

Page 1
MANUAL NO. YEU SIEP C710616 86A
To properly use the product, read this manual thoroughly and retain
for easy reference, inspection, and maintenance. Ensure the end user
receives this manual.
Type: SI-EL3 for A1000 Series
Technical Manual
YASKAWA AC Drive A1000 Option
ATTENTION!
This product can only be used on A1000 drives with firmware
version VSA901018 to VSA901099 installed.
RoHS Directive
RoHS Directive Stands for
the EU directive on the
Restriction of the Use of
Certain Hazardous
Substances in Electrical
and Electronic Equipment.
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 1
Page 2
Page 3
Table of Contents
1 PREFACE AND SAFETY . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 4
2 PRODUCT OVERVIEW. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 6
3 RECEIVING. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 7
4 POWERLINK OPTION COMPONENTS . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
5 INSTALLATION PROCEDURE . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
6 POWERLINK OPTION RELATED DRIVE PARAMETERS . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
7 DSP301 AND DSP402 SPECIFICATIONS. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
8 OBJECT DICTIONARY. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 18
9 CONFIGURING MANUFACTURER SPECIFIC CANOPEN OBJECTS . . . . . . . . . . . . . . . . . . . . . . . . . . . . 32
10 PROCESS DATA OBJECTS (PDO) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 33
11 DRIVE PARAMETER, MONITOR AND CONTROL REGISTER ACCESS . . . . . . . . . . . . . . . . . . . . . . . . 35
12 FAULT DIAGNOSIS AND POSSIBLE SOLUTIONS . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 36
13 SPECIFICATIONS. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 40
Copyright © 2013 YASKAWA EUROPE GMBH
All rights reserved. No part of this publication may be reproduced, stored in a retrieval system, or transmitted, in any form or by any means, mechanical,
electronic, photocopying, recording, or otherwise, without the prior written permission of YASKAWA. No patent liability is assumed with respect to the use of
the information contained herein. Moreover, because YASKAWA is constantly striving to improve its high-quality products, the information contained in this
manual is subject to change without notice. Every precaution has been taken in the preparation of this manual. YASKAWA assumes no responsibility for
errors or omissions. Neither is any liability assumed for damages resulting from the use of the information contained in this publication.
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 3
Page 4
1 Preface and Safety
1 Preface and Safety
YASKAWA manufactures products used as components in a wide variety of industrial systems and equipment. The selection and application of
YASKAWA products remain the responsibility of the equipment manufacturer or end user. YASKAWA accepts no responsibility for the way its
products are incorporated into the final system design. Under no circumstances should any YASKAWA product be incorporated into any product or
design as the exclusive or sole safety control. Without exception, all controls should be designed to detect faults dynamically and fail safely under
all circumstances. All systems or equipment designed to incorporate a product manufactured by YASKAWA must be supplied to the end user with
appropriate warnings and instructions as to the safe use and operation of that part. Any warnings provided by YASKAWA must be promptly
provided to the end user. YASKAWA offers an express warranty only as to the quality of its products in conforming to standards and specifications
published in the YASKAWA manual. NO OTHER WARRANTY, EXPRESS OR IMPLIED, IS OFFERED. YASKAWA assumes no liability for any
personal injury, property damage, losses, or claims arising from misapplication of its products.
Applicable Documentation
The following manuals are available for SI-EL3 Powerlink Option card:
Option Card
YASKAWA AC Drive A1000 Option Powerlink Installation Manual
Manual No.: YEU TOEP C710616 87A
Read this manual first.
The installation manual is packaged with the Powerlink Option and contains a basic overview of wiring, settings, functions, and fault diagnoses.
YASKAWA AC Drive A1000 Option Powerlink Technical Manual (this book)
Manual No.: YEU SIEP C710616 86A
The technical manual contains detailed information.
To obtain the technical manual access these sites:
Europe: http://www.yaskawa.eu.com
Other areas: contact a YASKAWA representative.
For the drive setup, refer to one of the documentation listed below.
YASKAWA Drive
Refer to the manual of the drive this option card is being used with.
The instruction manual for the drive covers basic installation, wiring, operation procedures, functions, troubleshooting, and maintenance information.
It also includes important information on parameter settings and how to tune the drive.
A Quick Start Guide is included with the drive. For the more detailed technical manual, visit YASKAWA’s home page.
Europe: http://www.yaskawa.eu.com
Other areas: contact a YASKAWA representative
Terms
Note: Indicates supplemental information that YASKAWA highly recommends be followed. Content identified by Note: is not related to personnel safety
or equipment damage safety messages.
Powerlink Option: YASKAWA AC Drive SI-EL3 Powerlink option card
Powerlink: Standard for CANopen over Ethernet according to the Ethernet POWERLINK Standardization Group
EPL: Ethernet Powerlink
Host: YASKAWA inverter 1000 series
LED: Light Emitting Diode
OPT, Option: The unit described in this document
FCS: Frame Check Sequence
INVR: Inverter register number
EPSG: Ethernet Powerlink Standardization Group
NMT: Network management
MN: Powerlink managing node
CN: Powerlink controlled node
RFG: Ramp function generator
Registered Trademarks
• Company names and product names listed in this manual are registered trademarks of those companies.
4 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 5
1 Preface and Safety
DANGER
W ARNING
CAUTION
NOTICE
DANGER
NOTICE
Supplemental Safety Information
Read and understand this manual before installing, operating, or servicing this option card. The option card must be installed according to this
manual and local codes.
The following conventions are used to indicate safety messages in this manual. Failure to heed these messages could result in serious or possibly
even fatal injury or damage to the products or to related equipment and systems.
Indicates a hazardous situation, which, if not avoided, will result in death or serious injury.
Indicates a hazardous situation, which, if not avoided, could result in death or serious injury.
Indicates a hazardous situation, which, if not avoided, could result in minor or moderate injury.
Indicates an equipment damage message.
General Safety
General Precautions
• The diagrams in this section may include drives without covers or safety shields to illustrate details. Be sure to reinstall covers or shields before operating any devices.
The option board should be used according to the instructions described in this manual.
• Any illustrations, photographs, or examples used in this manual are provided as examples only and may not apply to all products to which this manual is applicable.
• The products and specifications described in this manual or the content and presentation of the manual may be changed without notice to improve the product and/or the
manual.
• When ordering a new copy of the manual due to damage or loss, contact your YASKAWA representative or the nearest YASKAWA sales office and provide the manual
number shown on the front cover.
Heed the safety messages in this manual.
Failure to comply will result in death or serious injury.
The operating company is responsible for any injuries or equipment damage resulting from failure to heed the warnings in this
manual.
Do not expose the drive to halogen group disinfectants.
Failure to comply may cause damage to the electrical components in the option card.
Do not pack the drive in wooden materials that have been fumigated or sterilized.
Do not sterilize the entire package after the product is packed.
Do not modify the drive circuitry.
Failure to comply could result in damage to the drive and will void warranty.
YASKAWA is not responsible for any modification of the product made by the user. This product must not be modified.
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 5
Page 6
2 Product Overview
2 Product Overview
About This Product
The Powerlink Option (Model: SI-EL3) is an option card designed to connect the YASKAWA AC drive to a Powerlink network. Using this option
card a Powerlink master can:
• operate the drive
• monitor the drive operation status
• read or modify drive parameters.
The SI-EL3 option provides instant connectivity to a Powerlink network for the YASKAWA A1000 drive. The option contains support for the
Velocity mode according the CANopen Device Profile and Motion Control (DSP402) profile. It also contains YASKAWA vendor specific
CANopen objects based on the present CANopen option board specification.
The Powerlink Option supports the following communication profiles:
• DS 301 Ver. 4.02
• DSP 402 Ver. 3.0 Velocity Mode
Applicable Models
The option can be used with the drive models in Tab le 1 .
Table 1 Applicable Models
Drive Series Drive Model Number Software Version <1>
A1000
<1> See “PRG” on the drive nameplate for the software version number.
CIMR-A2A
CIMR-A4A
VSA901018 to VSA901099
6 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 7
3 Receiving
RUN ERR
L/A IN L/A OUT
S/E MS
L/A 2 L/A 1
MANUAL
3 Receiving
Please perform the following tasks after receiving the Powerlink Option:
• Inspect the Powerlink Option for damage.
If the Powerlink Option appears damaged upon receipt, contact the shipper immediately.
• Verify receipt of the correct model by checking the information on the PCB (see Figure 1).
• If you have received the wrong model or the Powerlink Option does not function properly, contact your supplier.
Contents and Packaging
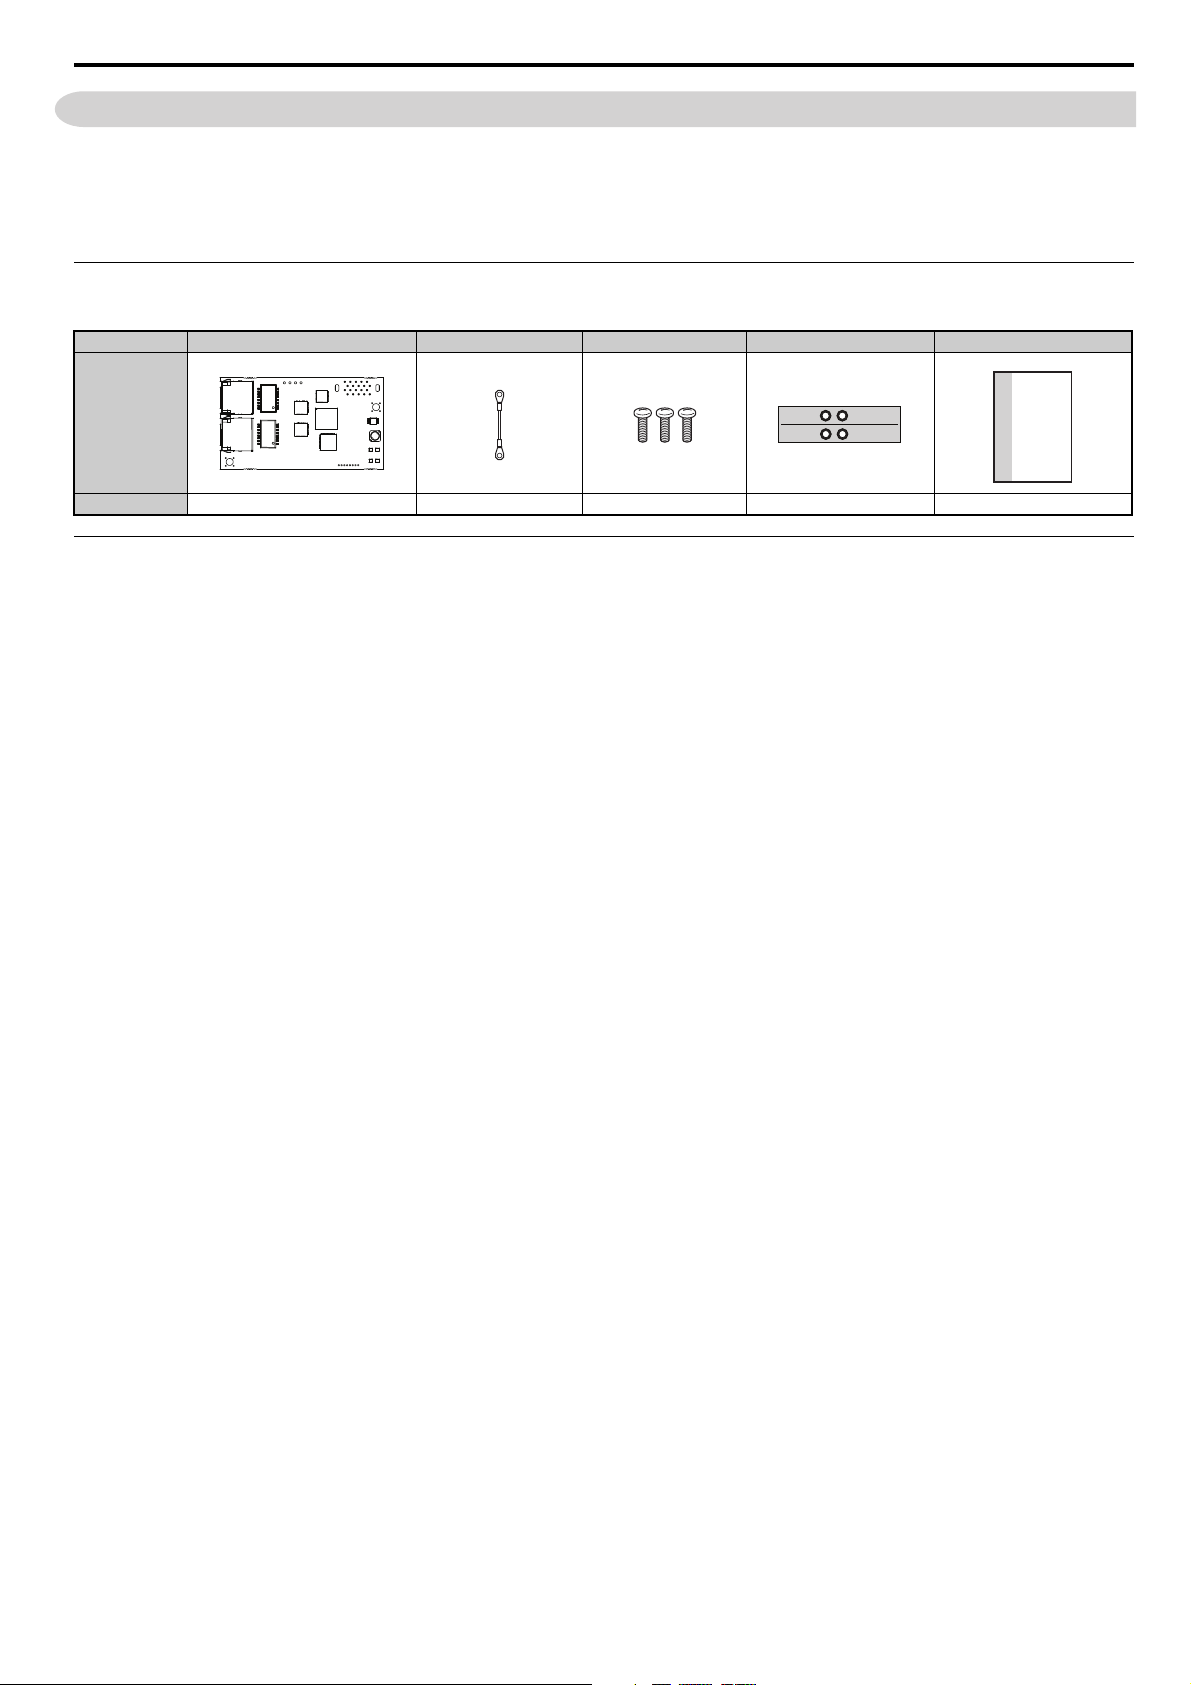
Table 2 Option Package Contents
Description: Option Card Ground Cable Screws (M3) LED Label Installation Manual
Quantity: 11311
Tool Requirements
A Phillips screwdriver PH1(#1) or PH2(#2) is required to install the Powerlink option.
Note: Tools required to prepare Powerlink cables for wiring are not listed in this manual.
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 7
Page 8
4 Powerlink Option Components
Underside
9
Looking from the connector
1
4
5
6
8 7
2
3
12
SI-EL3
SI-EL3
4 Powerlink Option Components
Powerlink Option
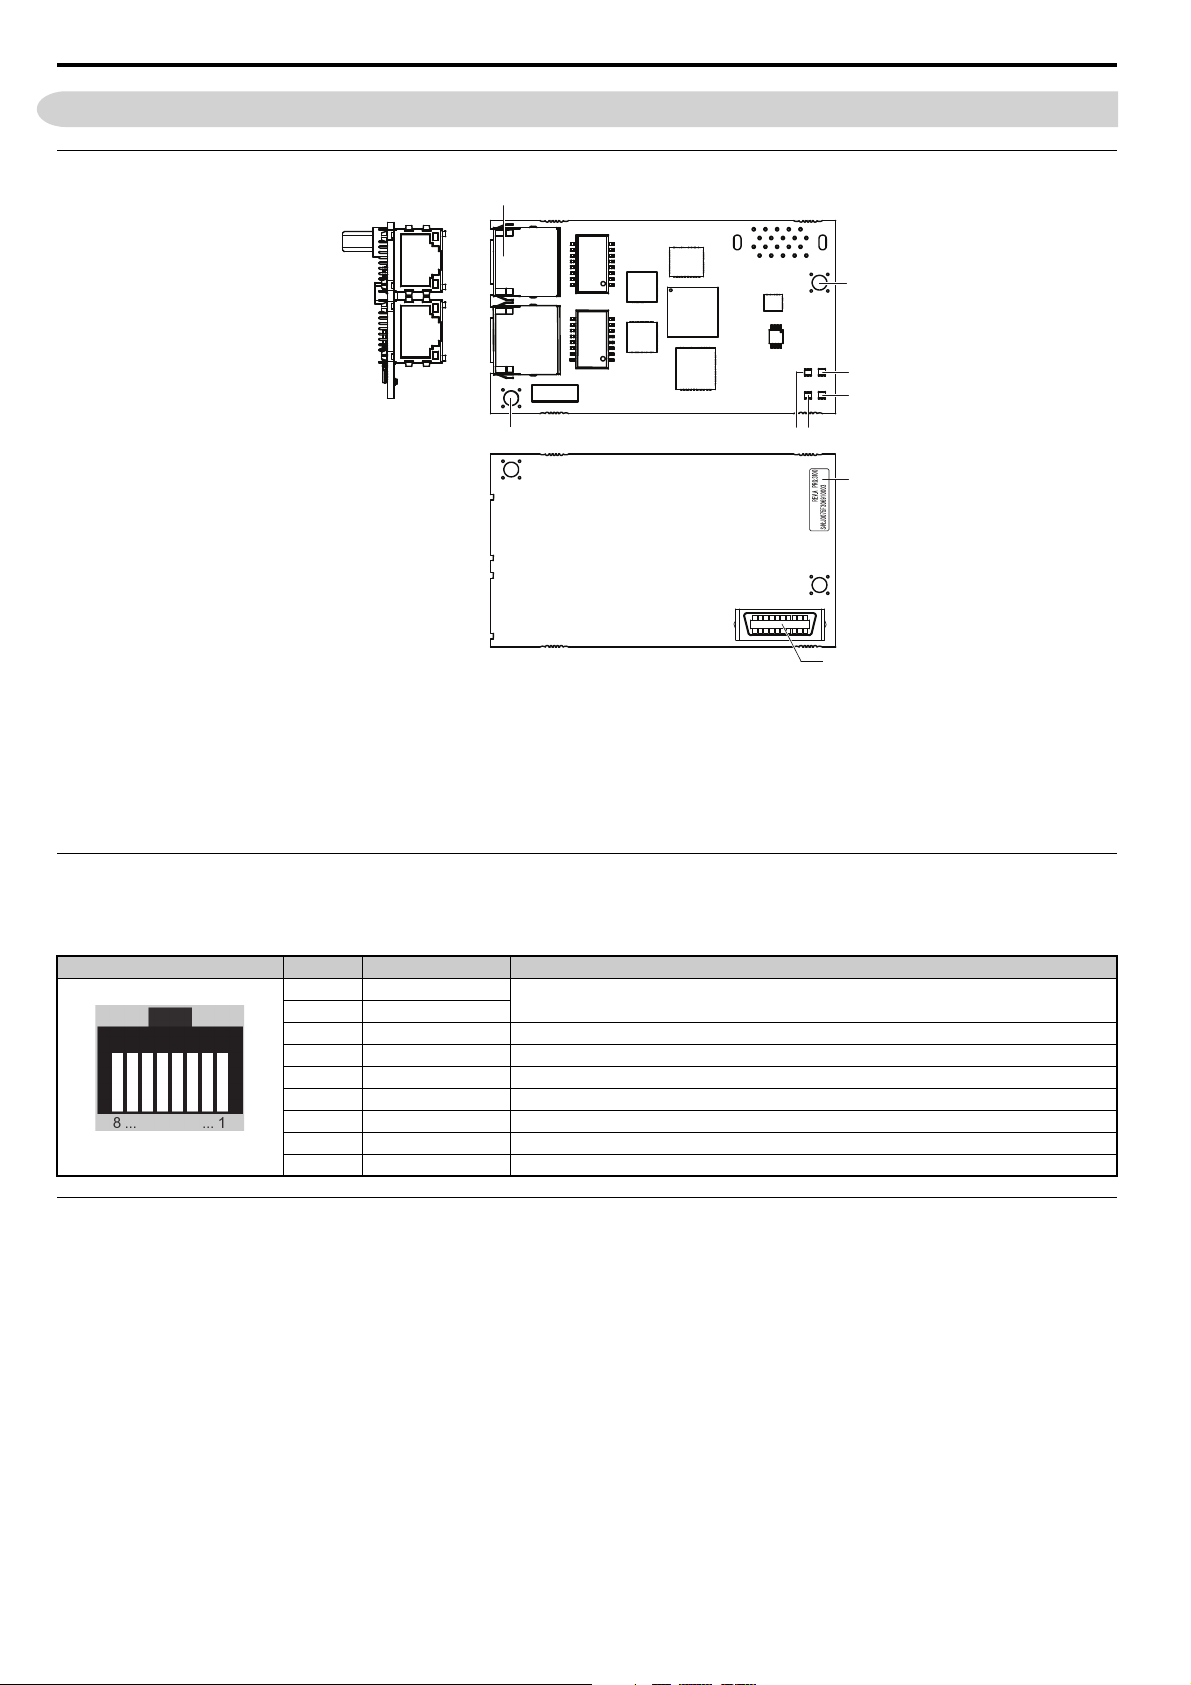
Figure 1
1 – Communication cable connector
(RJ45)
2 – Ground terminal (installation hole) 7 – LED (L/A 2)
3 – Model number 8 – LED (L/A 1)
4 – Installation hole 9 – Connector (CN5)
Figure 1 Option Card
5–LED (S/E)
6 – LED (MS)
For details on the LEDs, refer to Powerlink Option Status LEDs on page 8.
Communication connector
The Powerlink Option is connected to the network using a RJ45 connector. The pin assignment is explained in Table 3.
Table 3 Communication connector (RJ45)
Powerlink Connector Pin Signal Description
1TD+
2TD-
3 RD+ Receive data
4 – N.C. (Pins denoted as N.C. do not connect to any signal)
5 – N.C. (Pins denoted as N.C. do not connect to any signal)
6 RD- Receive data
7 – N.C. (Pins denoted as N.C. do not connect to any signal)
8 – N.C. (Pins denoted as N.C. do not connect to any signal)
Housing – Shield
Powerlink Option Status LEDs
The Powerlink Option has four LEDs that indicate the communication status. The indications conform with DS301 and DS303: Indicator
Specification.
LEDs L/A 1 and L/A 2: Ethernet Link/Activity 1 and 2
The Link/Activity indicators show the status of the physical link and show activity on the link period
S/E LED
A green lit Powerlink S/E LED indicates the status of the Powerlink network state machine.
A red lit Powerlink S/E LED indicates error on the EPL network side.
MS LED
The red Powerlink MS LED indicates the presence of any errors.
Send data
8 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 9
LED Color Display Meaning
Link Activity
1/2
S/E
MS Red
- Continuously Off No link
Green
- Continuously Off The device is in Init state
Green
Red
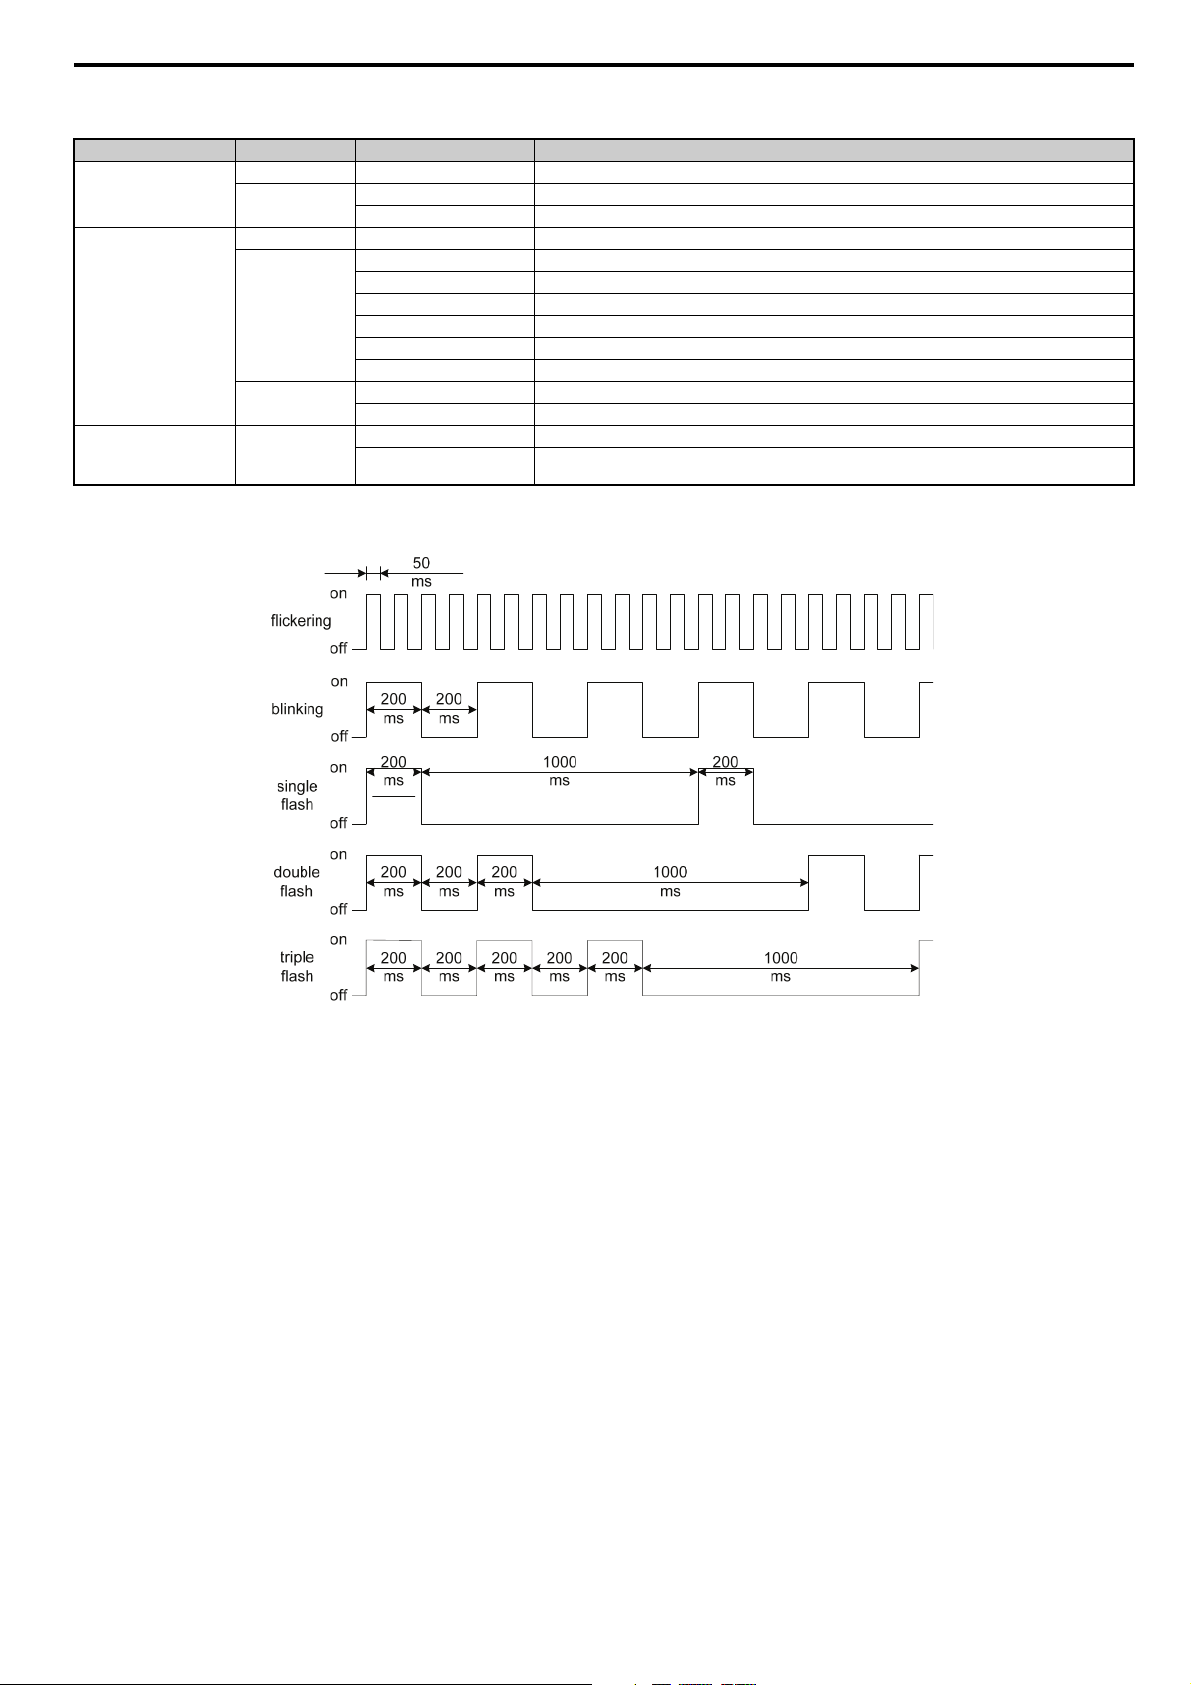
Figure 2 explains the indicator flash rates.
Figure 2
4 Powerlink Option Components
Tab l e 4 Understanding the Status LEDs
Continuously On The module is connected to Ethernet
Flickering There is traffic on Ethernet, data are being exchanged
Flickering The device is in NMT_CS_BASIC_ETHERNET state
Blinking The device is in NMT_CS_STOPPED state
Single flash The device is in NMT_CS_PRE_OPERATIONAL_1 state
Double flash The device is in NMT_CS_PRE_OPERATIONAL_2 state
Triple flash The device is in NMT_CS_READY_TO_OPERATE state
Continuously On The device is in NMT_CS_OPERATIONAL state
Off Normal operation
On An error has occurred
Off No error
On
Option card FATAL event has occurred (System has stalled execution. See Powerlink vendor object
0x4000 for the cause)
Figure 2 LED Flash Rates and Meaning
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 9
Page 10
5 Installation Procedure
DANGER
W ARNING
NOTICE
5 Installation Procedure
Section Safety
Electric Shock Hazard
Power to the drive must be shut off when installing this option card.
Even though the power has been shut off, voltage still remains in the drive’s DC bus. Wait before removing the front cover once the
drive has been turned off.
The CHARGE light on the drive will go out after voltage in the DC bus drops below 50 V, at which point it is safe to remove the
front cover.
Due to the risk of electric shock, be sure that all LEDs have gone out and that the DC bus voltage has reached a safe level prior to
performing any work on the drive.
Electrical Shock Hazard
Do not remove the front cover of the drive while the power is on.
Failure to comply could result in death or serious injury.
The diagrams in this section may include drives without covers or safety shields to show details. Be sure to reinstall covers or
shields before operating any devices. The option board should be used according to the instructions described in this manual.
Do not allow unqualified personnel to use equipment.
Failure to comply could result in death or serious injury.
Maintenance, inspection, and replacement of parts must be performed only by authorized personnel familiar with installation,
adjustment, and maintenance of this product.
Do not touch the option card while the power supply to the drive is switched on.
Failure to comply could result in death or serious injury.
Do not use damaged wires, place excessive stress on wiring, or damage the wire insulation.
Failure to comply could result in death or serious injury.
Damage to Equipment
Observe proper electrostatic discharge procedures (ESD) when handling the option card, drive, and circuit boards.
Failure to comply may result in ESD damage to circuitry.
Never shut the power off while the drive is outputting voltage.
Failure to comply may cause the application to operate incorrectly or damage the drive.
Do not operate damaged equipment.
Failure to comply may cause further damage to the equipment.
Do not connect or operate any equipment with visible damage or missing parts.
Tighten all terminal screws to the specified tightening torque.
Loose electrical connections could result in death or serious injury by fire due to overheating of electrical connections.
Do not use unshielded cable for control wiring.
Failure to comply may cause electrical interference resulting in poor system performance.
Use shielded twisted-pair wires and ground the shield to the ground terminal of the drive.
Properly connect all pins and connectors.
Failure to comply may prevent proper operation and possibly damage equipment.
Check wiring to ensure that all connections are correct after installing the option card and connecting any other devices.
Failure to comply may result in damage to the option card.
10 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 11
5 Installation Procedure
RUN ERR
L/A IN L/A OUT
RUN ERR
L/A IN L/A OUT
L/A 1 S/E
L/A 2 MS
7
1
5
6
9
10
2
3
4
8
11
2
1
Prior to Installing the Option Card
Prior to installing the Powerlink Option, wire the drive and make necessary connections to the drive terminals. For more information on wiring and
connecting the drive, refer to the manual packaged with the drive. Verify that the drive runs normally without the option installed.
Installing the Option
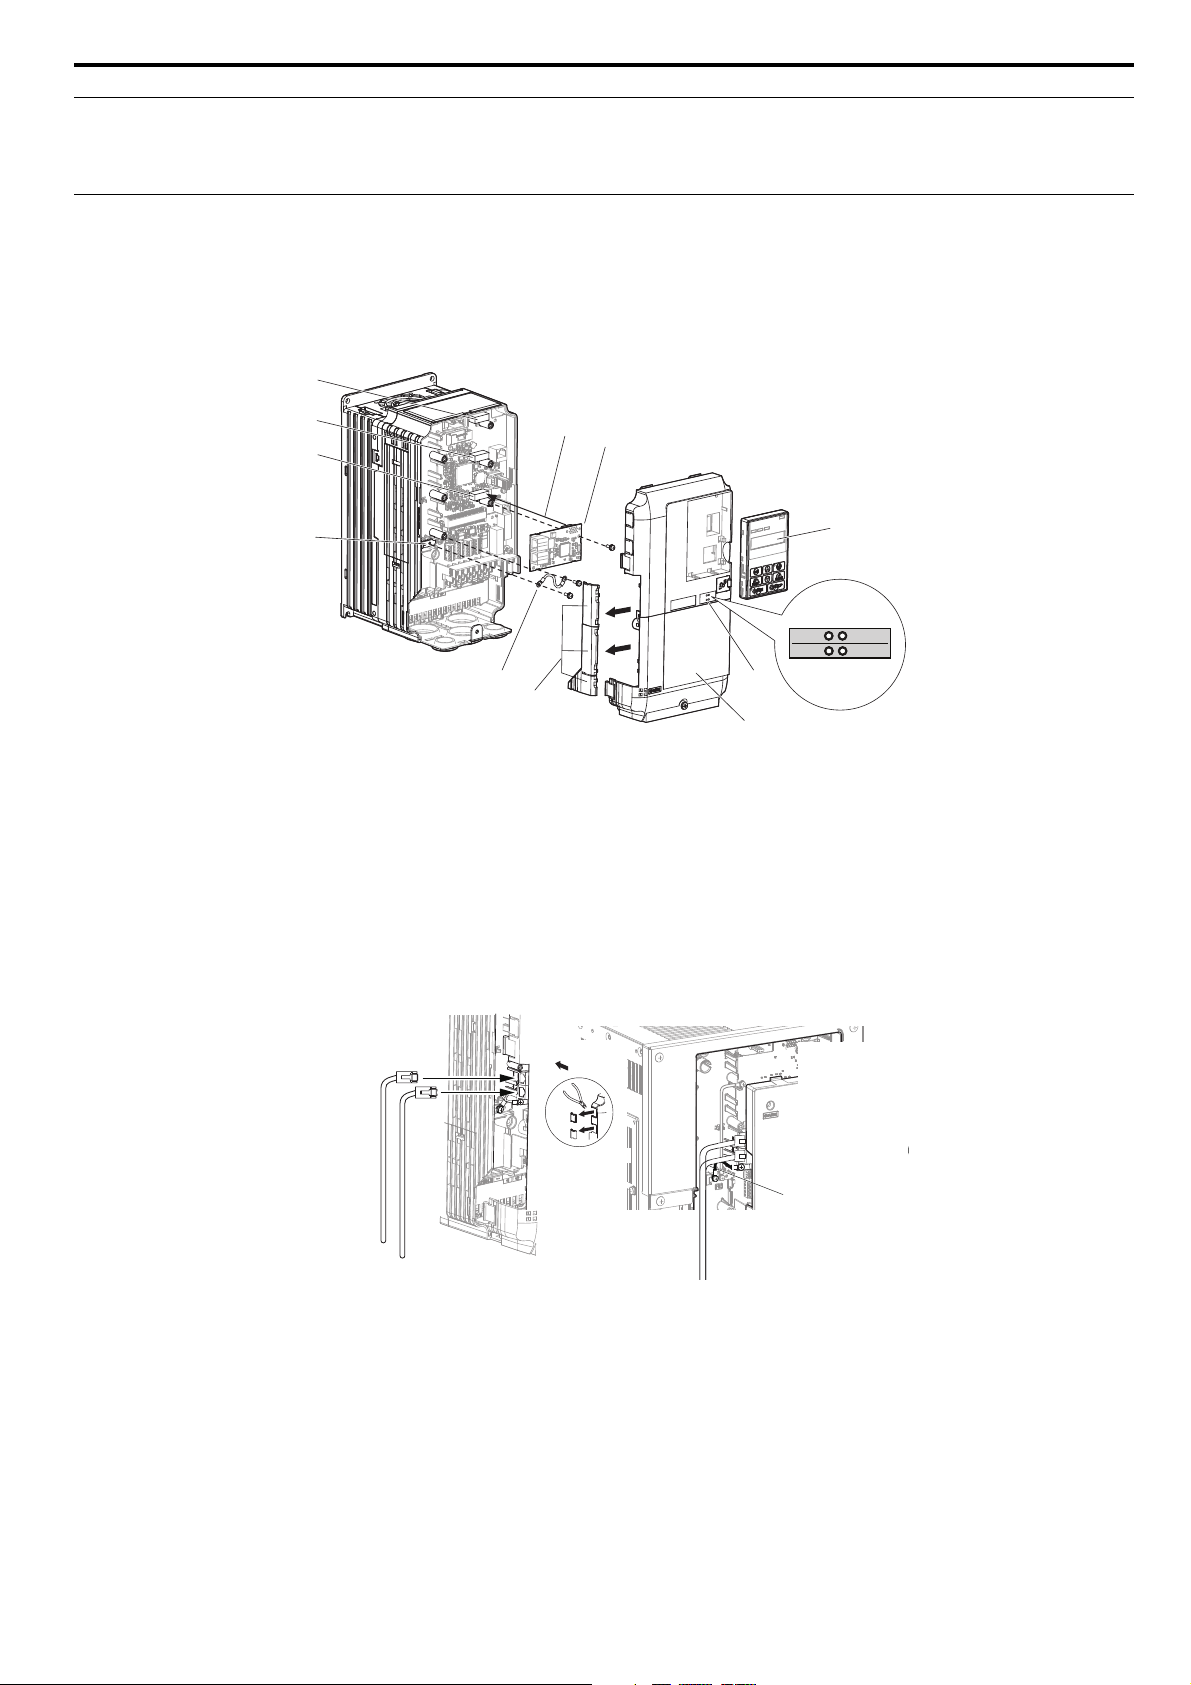
1. Shut off power to the drive, wait the appropriate amount of time for voltage to dissipate, then remove the operator (9) and front cover (11).
Refer to the drive manual for direction on removing the front cover.
2. Insert the CN5 connector on the option (5) into the CN5-A connector on the drive (3), then fasten it into place using one of the screws
included with the option.
Connect the ground wire (7) to the ground terminal (4) using one of the screws provided with the option.
Note: There are only two screw holes on the drive for ground terminals. If three option cards are connected, two of the ground wires will need to share
Figure 3
the same ground terminal.
1 – Connector CN5-C 7 – Ground wire
2 – Connector CN5-B 8 – Use with cutters to create an
3 – Connector CN5-A 9 – Operator
4 – Drive grounding terminal (FE) 10 – LED label
5 – Insert connector CN5 here 11 – Front cover
6 – Option card
Figure 3 Installing the Option Card
opening for cable lines
3. Prepare RJ45 network cable connectors.
In the drives CIMR-A2A0004 to 0040 and 4A0002 to 0023 the network cable must be routed to the outside through the drive top cover. Use
a pair of diagonal cutters to cut out the perforated openings at the left side of the top cover. Make sure no sharp edges that can damage the
cable remain.
Figure 4
Drives 2A0056 and above, and 4A0031 and above have enough space to keep all wiring inside the unit.
1 – Opening for network cables
(CIMR-A2A0004 to 0040, 4A0002 to 0023)
Figure 4 Wiring Routing
4. Plug in the RJ45 network cable connector into the option.
The network can be established in star, tree, line or ring architecture.
2 – Space for wiring
(CIMR-A2A0056 to 0211, 4A0031 to 0165)
5. Reinstall the front cover back onto the drive as it was before.
Note: 1. Take care when wiring the option card so that the front cover easily fits back onto the drive.
2. Install Cable Cover option to maintain the drive Enclosure Type integrity.
6. Attach the LED label (10) packaged with the option as shown in Figure 3.
7. Switch on the drive power supply.
An “AEr” Alarm message indicating that the node address is set to 0 will appear on the drive display.
Set the node address in parameter F6-72.
8. Cycle the power supply to activate the changed settings. Installation complete.
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 11
Page 12
5 Installation Procedure
PRG : 1018
IND.CONT.EQ.
7J48 B
CIMR-AC2A0021FAA
YASKAWA ELECTRIC CORPORATION
MADE IN JAPAN
:
: AC3PH 200-240V 50/60Hz 24A/18.9A
: AC3PH 0-240V 0-400Hz 21A/17.5A
: 3.5 kg
:
:
: E131457 IP20
PASS
MODEL
MAX APPLI. MOTOR : 5.5kW / 3.7kW REV : A
INPUT
OUTPUT
MASS
O / N
S / N
FILE NO
TYPE 1 ENCLOSURE
AC drive model
Input specifications
Output specifications
Lot number
Serial number
Firmware version
Enclosure type
Normal Duty Amps / Heavy Duty Amps
Communication Cable Specifications
To ensure proper performance, YASKAWA recommends using Powerlink dedicated Cat5e communication cables.
Network Termination
The Powerlink network does not require a termination resistor if the drive is the last node in the network. Network termination is realized by the
ASIC of the Powerlink option card.
XDD File
For easy network implementation of drives equipped with an Powerlink Option, the XDD file can be obtained from:
Europe: http://www.yaskawa.eu.com
Other areas: contact a YASKAWA representative
Identification of Drive Firmware Version
1. Read out firmware version from drive digital operator.
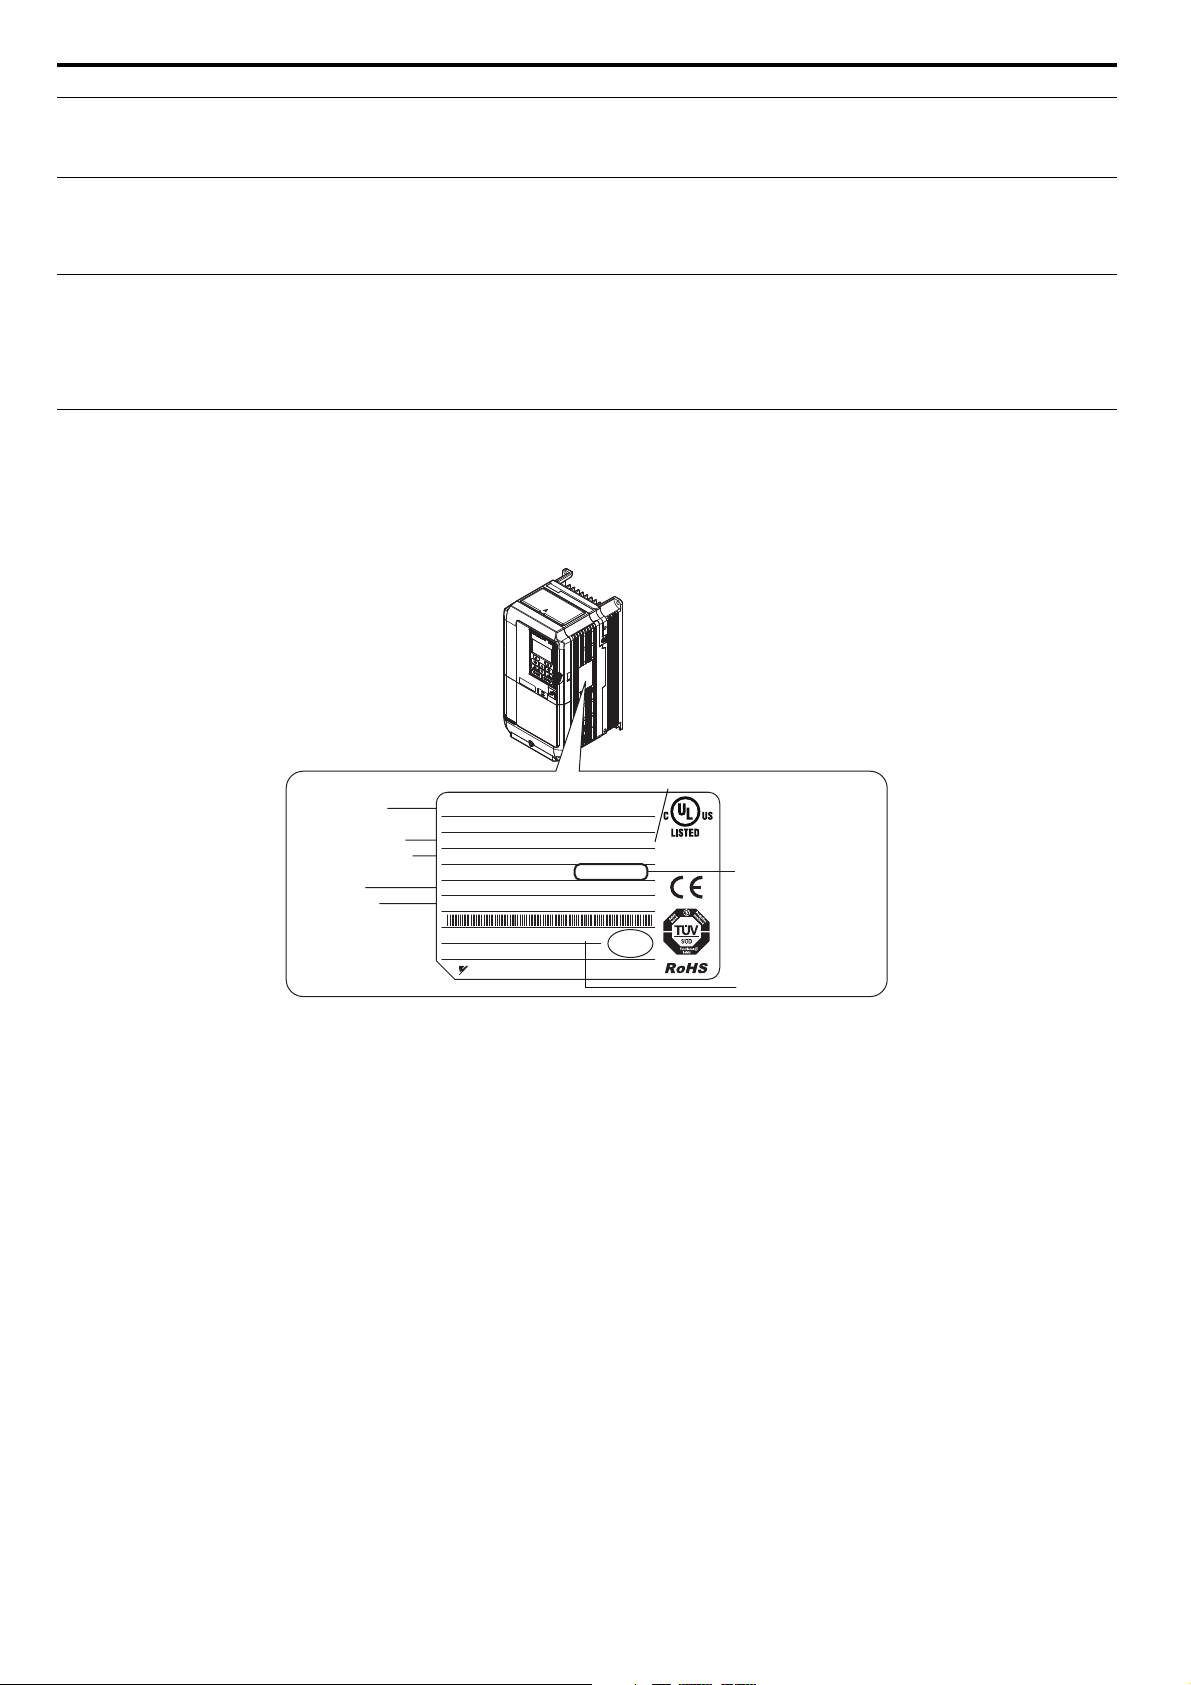
Check monitor parameter U1-25 when the drive is switched ON. The display shows the last four digits of the firmware version and the value should
be in the range of 1018 ~ 1099.
2. Verifying firmware version on drive nameplate
Figure 5
Figure 5 Verifying firmware version on drive nameplate
12 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 13
6 Powerlink Option Related Drive Parameters
6 Powerlink Option Related Drive Parameters
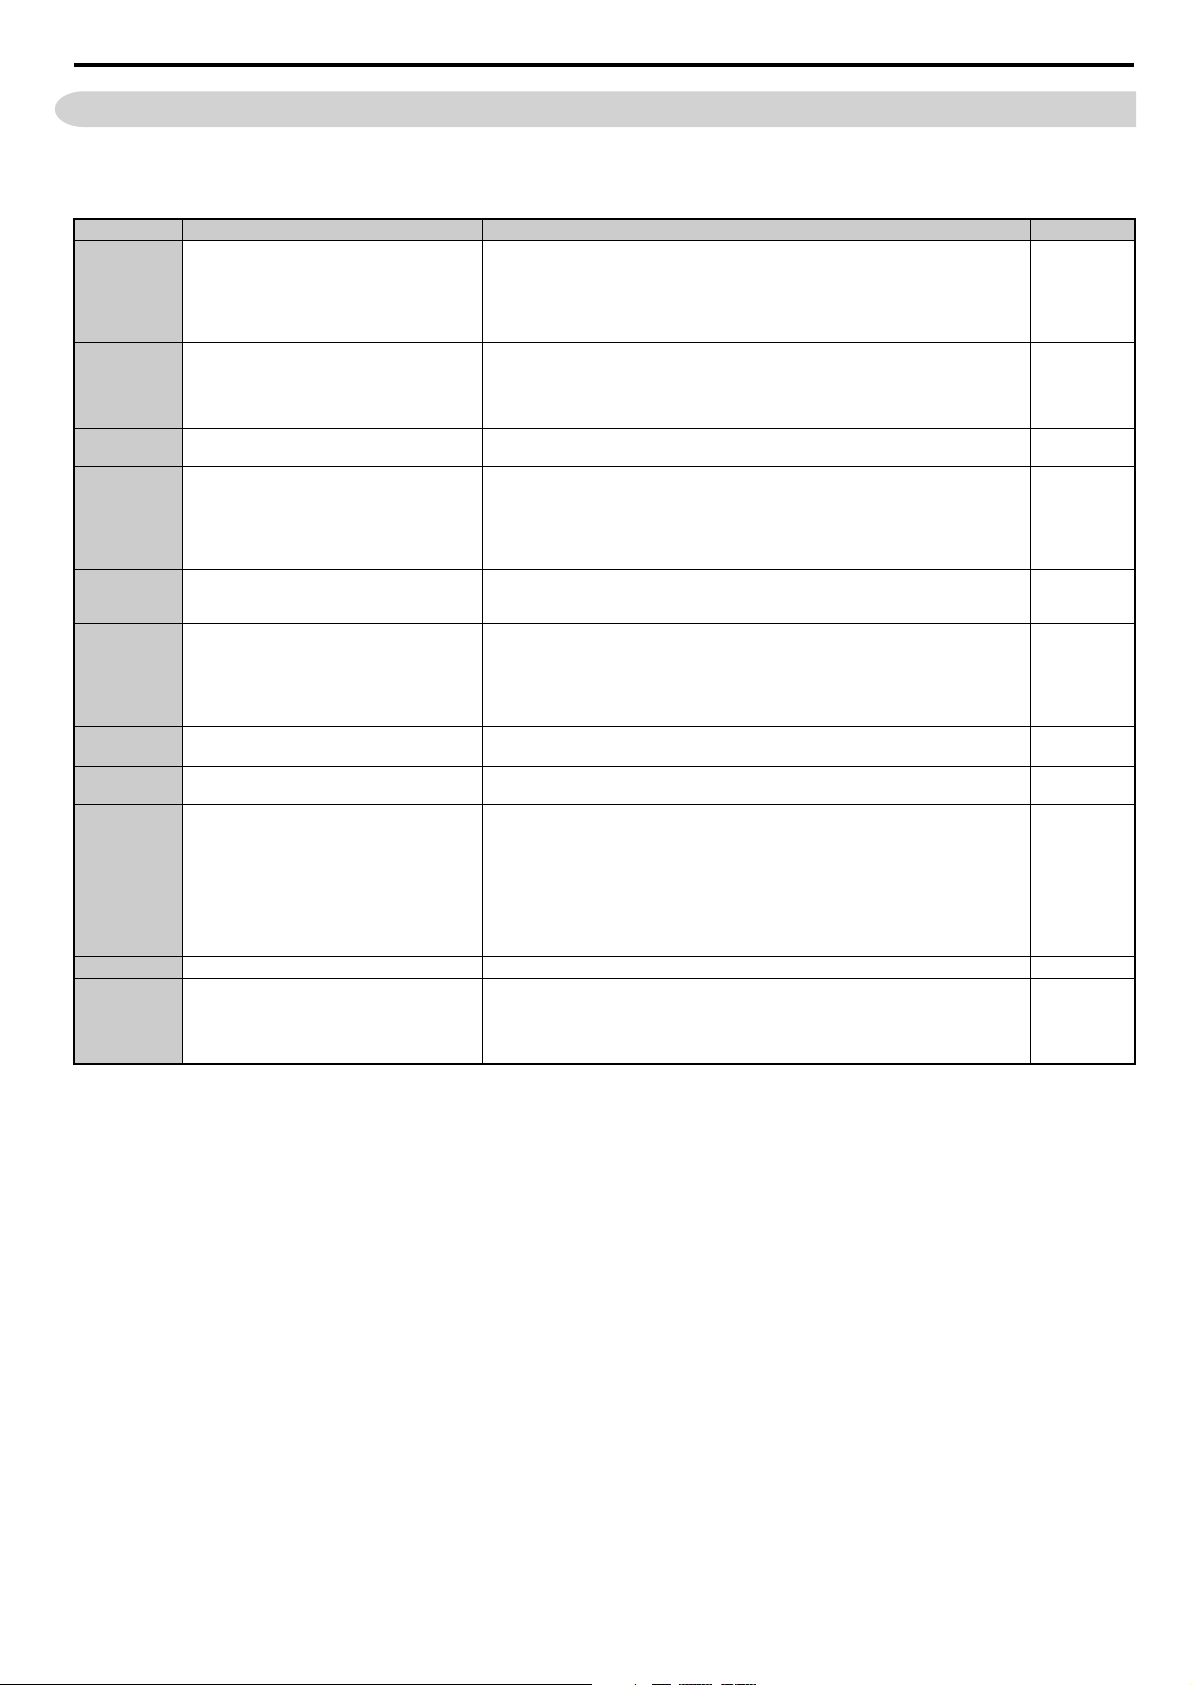
The drive parameters listed in Tab le 5 have influence on some functions of the SI-EL3 option card. Check these parameters before starting network
communications.
Table 5 Parameter Settings
No.
b1-01
<1>
b1-02
<1>
E2-04
<2>
F6-01 Operation Selection after Communications Error
F6-02 External Fault Detection Conditions (EF0)
F6-03
F6-06
<4>
F6-07
<8>
F6-08 Reset Communication Related Parameters
F6-72 Powerlink Node ID Sets the Node ID that is used to access the drive in a Powerlink network. 0
o1-03
<7>
<1> To start and stop the drive from an Powerlink
to 3.
<2> E2-04 is necessary to set up when the Drive Profile DSP402 objects are used.
<3> If set to 3, then the drive will continue to operate when an EF0 fault is detected. Take proper safety measures, such as installing an emergency stop switch.
<4> This parameter might not appear in certain drives. Furthermore its availability is limited depending on the control mode selection. For details refer to the Technical Manual for the drive
the option card is used with.
<5> If the drive is set to receive the torque reference/limit from the network (F6-06 = 1) make sure the value is set appropriately by the controller. If no torque reference/limit value is entered
the motor will not produce torque.
<5> For details refer to the Technical Manual for the drive the option card is used with.
<6> The default value depends on the drive used and/or the drive software version. For details refer to the Technical Manual for the drive.
<7> Changing o1-03 changes the units for input object 2010 (Hex) (frequency reference), output object 2110 (Hex) (output frequency) and 2200 (Hex) (motor speed). Confirm parameter o1-
03 is set to 2 and parameter E2-04 is set to the correct value when using Drive Profile DSP402.
<8> For details refer to the Technical Manual for the drive the option card is used with.
Frequency Reference Selection
Run Command Selection
Motor 1 Motor Poles
Stopping Method for External Fault from
Communication Option Board
Torque Reference/Torque Limit selection from
Communications Option
NetRef/ComRef Selection Function
Digital Operator Display Selection
Name Description Default
Selects the frequency reference input source
0: Operator - Digital preset speed d1-01 to d1-17
1: Terminals - Analog input terminals
2: MEMOBUS/Modbus communications
3: Option card
4: Pulse Input (Terminal RP)
Selects the run command input source
0: Digital Operator - RUN and STOP keys
1: Digital input terminals S
2: MEMOBUS/Modbus communications
3: Option card
Set the number of motor poles described on the motor nameplate.
2 to 48
Determines drive response when a bUS error is detected during communications with the
Option
Powerlink
0: Ramp to Stop
1: Coast to Stop
2: Fast-Stop
3: Alarm Only
Sets the condition for external fault detection (EF0)
0: Always detected
1: Detected only during operation
Determines drive response for external fault input (EF0) detection during Powerlink
communication
0: Ramp to Stop
1: Coast to Stop
2: Fast-Stop
3: Alarm Only
0: Torque reference/torque limit via network communications are disabled.
<3>
<3>
1: Torque reference/torque limit via network communications are enabled. <5>
0: Multi-step speed reference disabled (F7 mode)
1: Multi-step speed reference allowed (V7 mode)
Determines if communication-related parameters are set back to their original default values
when the drive is initialized.
0: Do not reset F6- and F7- parameters when the drive is initialized using parameter
A1-03.
1: Rest F6- and F7- parameters when the drive is initialized using parameter A1-03.
Note: Setting this parameter does not affect communication-related
parameters. Setting this parameter only determines if
communication-related parameters (F6- and F7-) are
also reset when A1-03 is used to initialize the drive.
Sets the units to display the frequency reference and output frequency.
0: 0.01 Hz
1: 0.01% (100% = E1-04)
2: r/min (enter the number of motor poles to E2-04/E4-04/E5-04)
3: User defined by parameters o1-10 and o1-11
master device using serial communications, set b1-02 to 3. To control the frequency reference of the drive via the master device, set b1-01
<6>
1
4
1
0
1
0
0
0
<6>
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 13
Page 14
7 DSP301 and DSP402 Specifications
7 DSP301 and DSP402 Specifications
Network communication on Powerlink is based on the DSP301 communication profile and the CANopen DSP402 device profile for drives and
motion control. This profile specifies mandatory objects that will be implemented as well as manufacturer specific and optional objects.
Process Data Objects (PDOs) are used for I/O exchange and Service Data Object (SDO) for explicit messaging. The time for transmitting PDOs is
significantly lower than the time for transmitting SDO, therefore, communication objects like command/reference are mapped onto PDOs as
standard.
All CANopen communication objects can be accessed via SDO. The SDO allow acknowledged access to communication objects, i.e., the
communication adapter confirms the intended access.
7.1 Modes
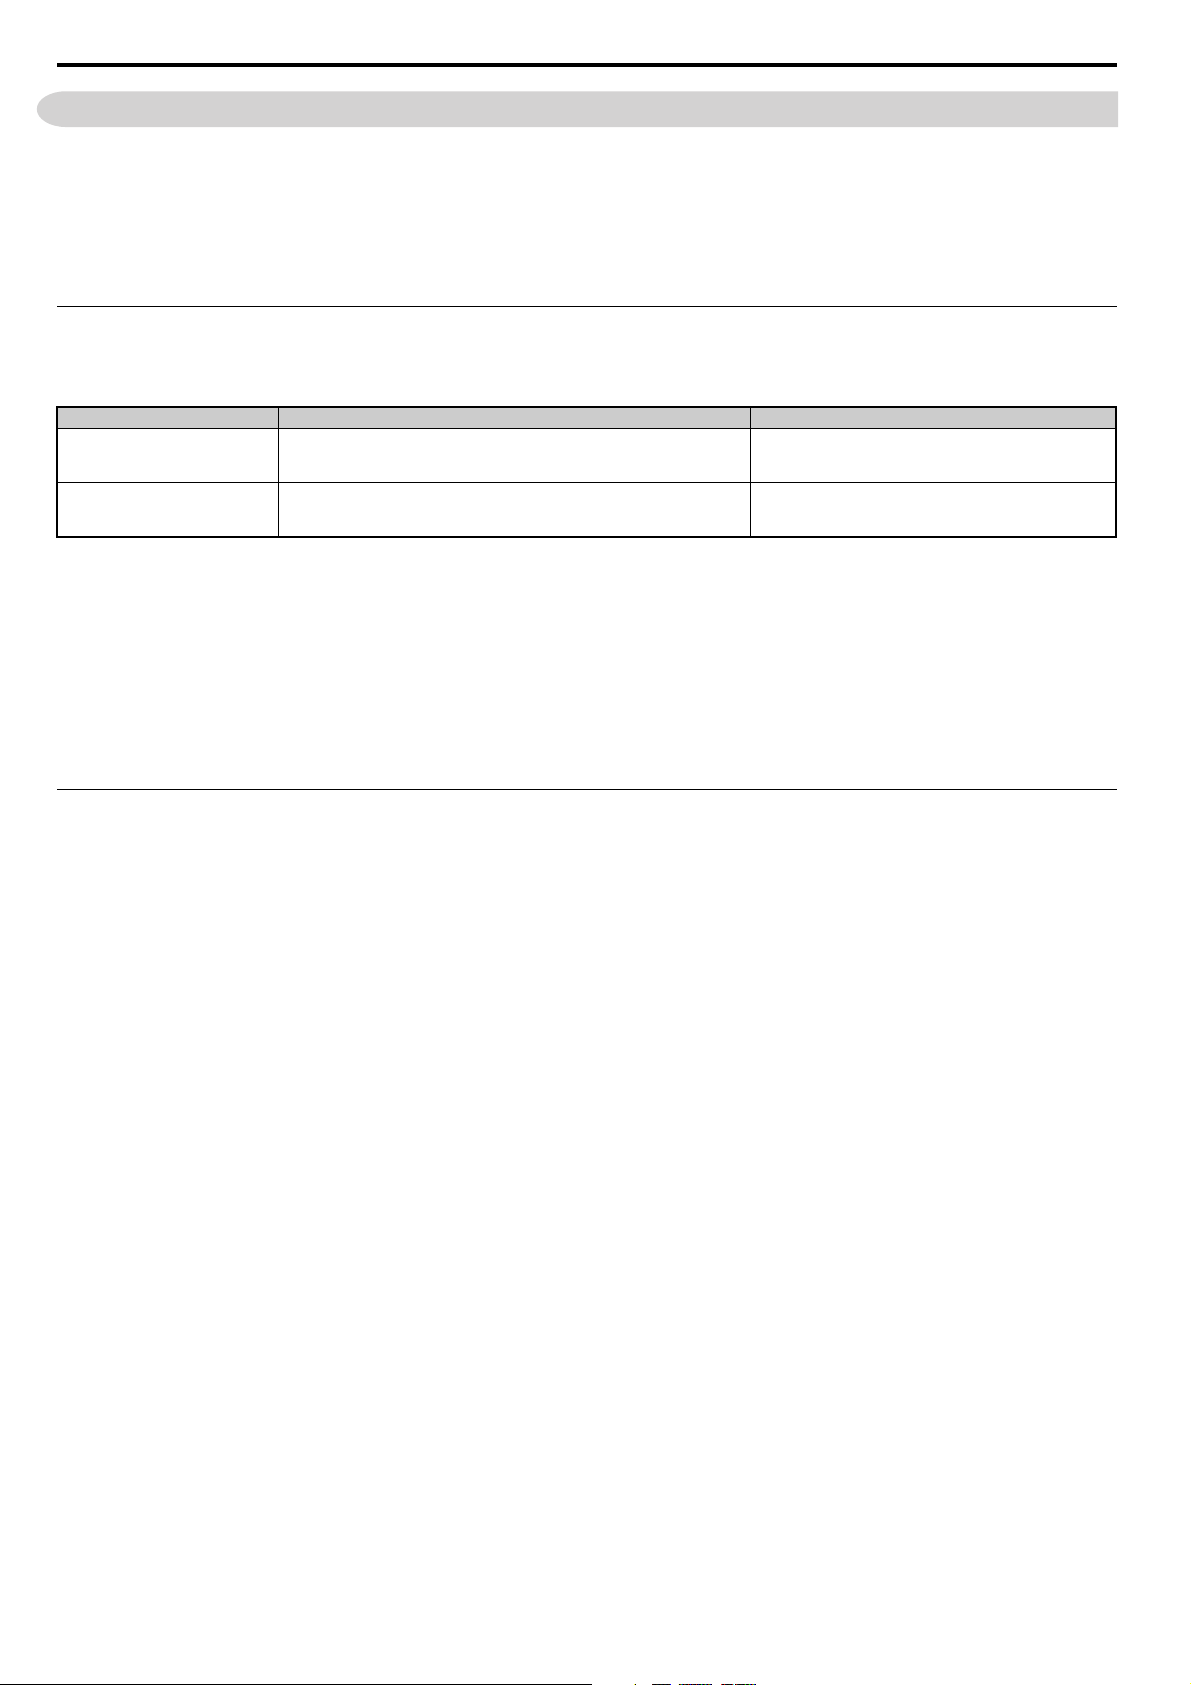
The A1000 series Powerlink option will support two operating modes:
Table 6 States of the Powerlink State Machine
Mode Description Mode Verification
DSP402 Velocity mode
Vendor specific mode
(DSP402 profile bypass)
DSP402 drive profile/vendor mode activation is done automatically by the option within the following constraints:
1. If an RxPDO mapping has been assigned to DSP402 control word 0x6040 and Powerlink is in the SAFEOP or OP state the DSP402 profile will be
processed.
2. If the Powerlink state machine is NOT in the SAFEOP or OP state and an SDO write request is performed on the DSP402 0x6040 control word the
DSP402 profile will be processed.
3. If the Powerlink state machine is NOT in the SAFEOP or OP state and an SDO read request is performed on the DSP402 0x6041 status word the
DSP402 profile will be processed.
4. Otherwise the vendor specific control word will be accessed normally.
The numbers of poles has to be set correctly and the display unit of the inverter has to be switched to rpm for proper operation. Refer to Table 5 for
further details.
In this mode the drive can be controlled using standardised I/O objects. This
simple mode allows to control the velocity of the drive with limits and ramp
functions.
In this mode the DSP402 state machine processor in the option is bypassed and the
drive native control/status words are used. Besides controlling the drive, this mode
allows flexible access to drive parameters and monitors.
DSP402 object 0x6061 (Modes of operation display) = 2
DSP402 object 0x6061 (Modes of operation display) = -2
7.2 Implemented CANopen Objects/Components
The following message types are implemented:
• SDO (Service Data Object) uses asynchronous data transmission and is used to access objects without mapping them to an I/O (PDO) connection.
With SDO communication, the user will have access to all CANopen objects in the module.
• PDO (Process Data Object)
The PDO object is used for I/O communication.
• Error Signalling
Error register and error history (pre-defined error field) are accessible via 1001 and 1003 objects, respectively. The error code is accessible via
603F object.
14 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 15
7 DSP301 and DSP402 Specifications
Start
Not Ready to
Switch On
Switch On
Disabled
Ready to Switch
On
Switched On
Operation Enable Quick Stop Active
Fault
Reaction
Active
Fault
0
1
14
13
2 7
3 6
4 5
10
11
16
8
9 12
Power
Disabled
Fault
15
Power
Enabled
DSP402 State Machine
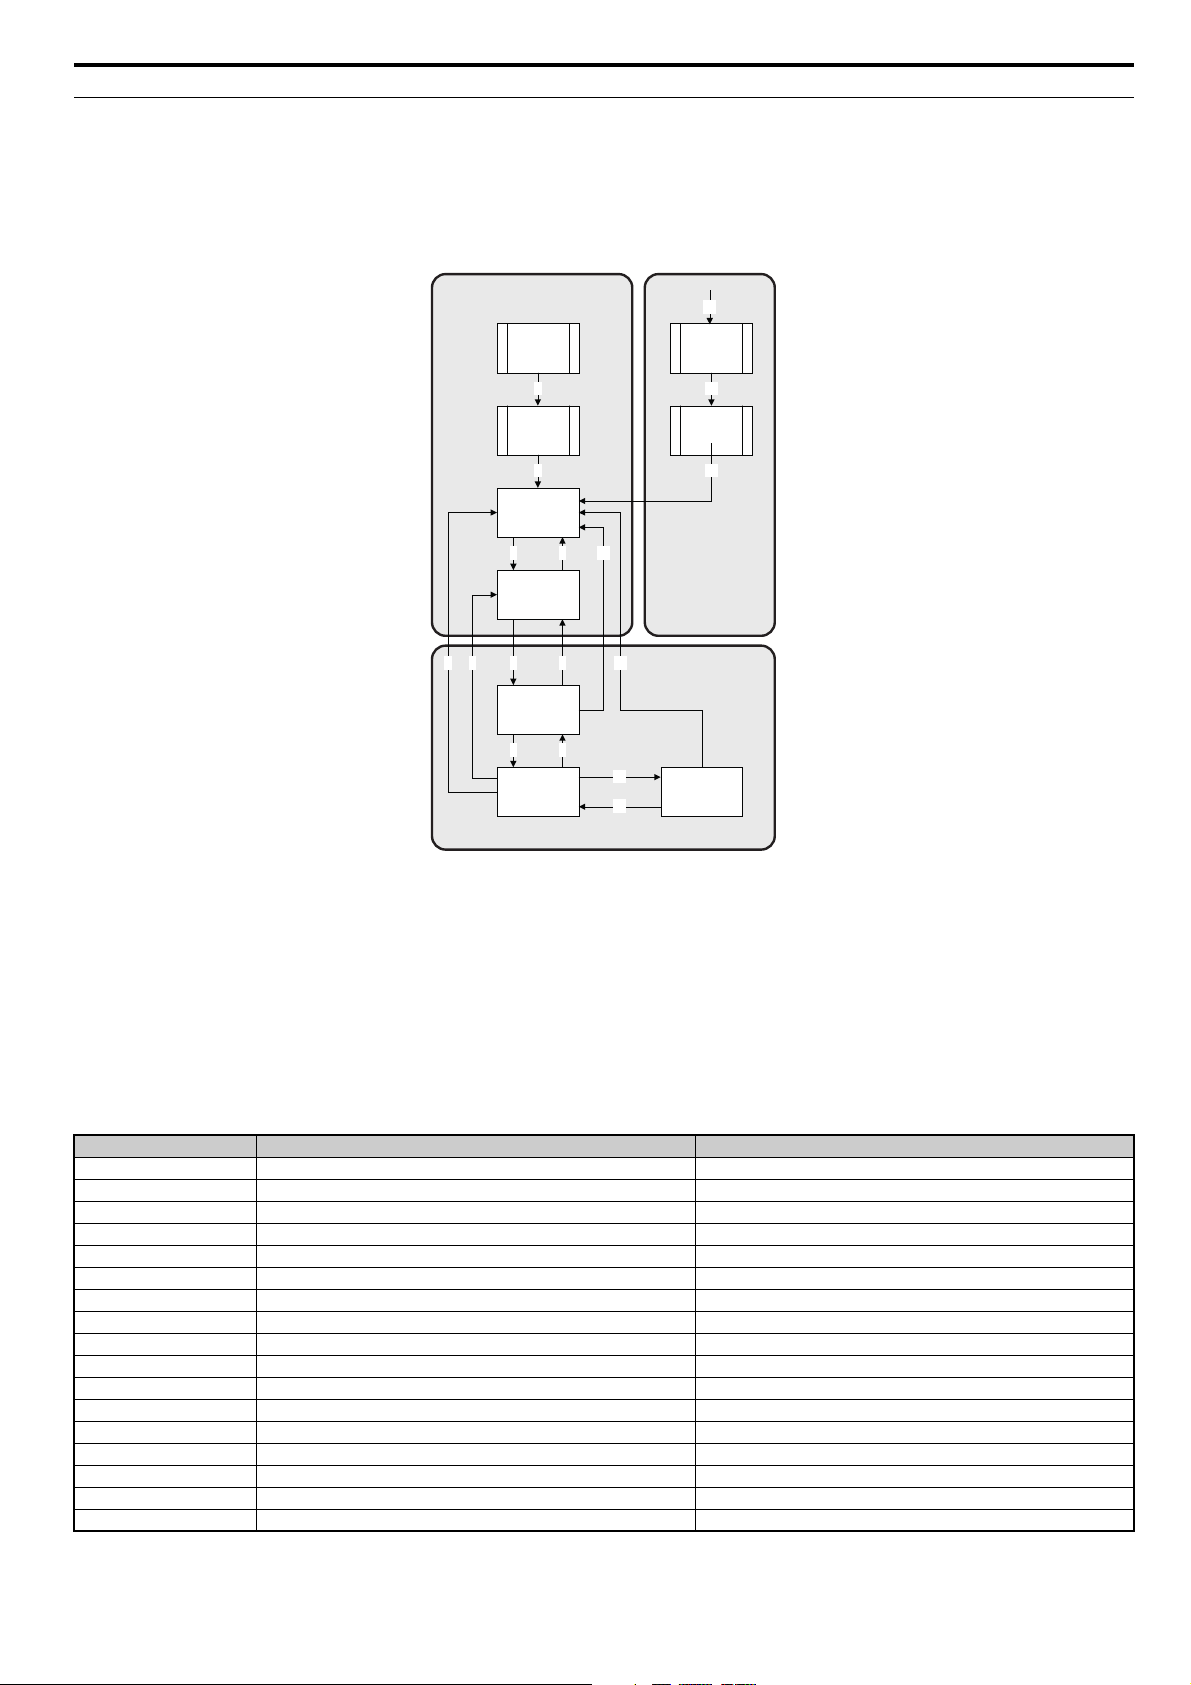
The state machine of the inverter is described in the CANopen DSP402 specification.
CANopen DSP402 State Diagram
At any time the Powerlink
either sent with the control word or triggered by an internal action. All the possible events and the corresponding transition number are listed in
Ta bl e 7.
Figure 6
option card will be in one of the following states. The events that are able to trigger a transition between the states are
Transition 16 is only available while the drive is performing the quick stop action. When completed, transition will automatically be processed.
CANopen DS402 State Transition Definition
The YASKAWA Powerlink option must be in the state Operation Enable in order to accept frequency and operation commands. In Table 13 the
events needed to change between different states are described. Some events are internally triggered, but most of the events are triggered from the
control word received from the bus.
CANopen DSP402 Event Description
The following state transitions are available in the CANopen DSP402 drive profile. Transition 0 and 1 are triggered at start-up and when all start-up
tests are performed the module will be in state 3. Some commands like fault reset can be triggered from more then one place. For example, the reset
command can be triggered both from the bus with the control word, or from the application drive.
State Transition Number Transition Name DSP402 Event
0 Startup => Not Ready To Switch On Reset
1 Not ready to switch on => Switch on disabled Self test and init successful
2 Switch on disabled => Ready to switch on Shutdown command received
3 Ready to switch on => Switched on disabled Switch on command received
4 Switched on => Operation enabled Enable operation command received
5 Operation enabled => Switched on Disable operation command received
6 Switched on => Ready to switch on Shutdown command received
7 Ready to switch on => Switch on disabled Quickstop command received
8 Operation enabled => Ready to switch on Shutdown command received
9 Operation enabled => Switch on disabled Disable voltage command received
10 Switched on => Switch on disable Disable voltage or quickstop command received
11 Operation enabled => Quick stop active Quickstop command received
12 Quick stop active => Switch on disabled Quickstop completed or Disable voltage command received
13 All states => Fault reaction active Fatal fault has occurred in the drive
14 Fault reaction active => Fault The fault action is completed
15 Fault => Switch on disabled Fault reset command received
16 Quick stop active => Operation enabled Enable operation command received
Figure 6 DSP402 State Diagram
Table 7 Event description table
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 15
Page 16
7 DSP301 and DSP402 Specifications
Factor
function
Velocity
limit
function
Reverse
factor
function
Reverse
factor
function
vl dimension
factor
vl velocity
actual value
vl set-point
factor
bit 11 - internal limit active
Ramp
function
Velocity
control
function
vl target velocity
vl setpoint factor
vl dimension factor
vl dimension factor
vl velocity acceleration
vl velocity deceleration
vl velocity quick stop
bit 8 - halt
bit 4 - enable ramp
controlword
statusword
bit 5 - unlock ramp
bit 6 - reference ramp
vl velocity min/max amount
vl dimension factor
vl dimension
factor
vl set-point
factor
vl velocity
demand
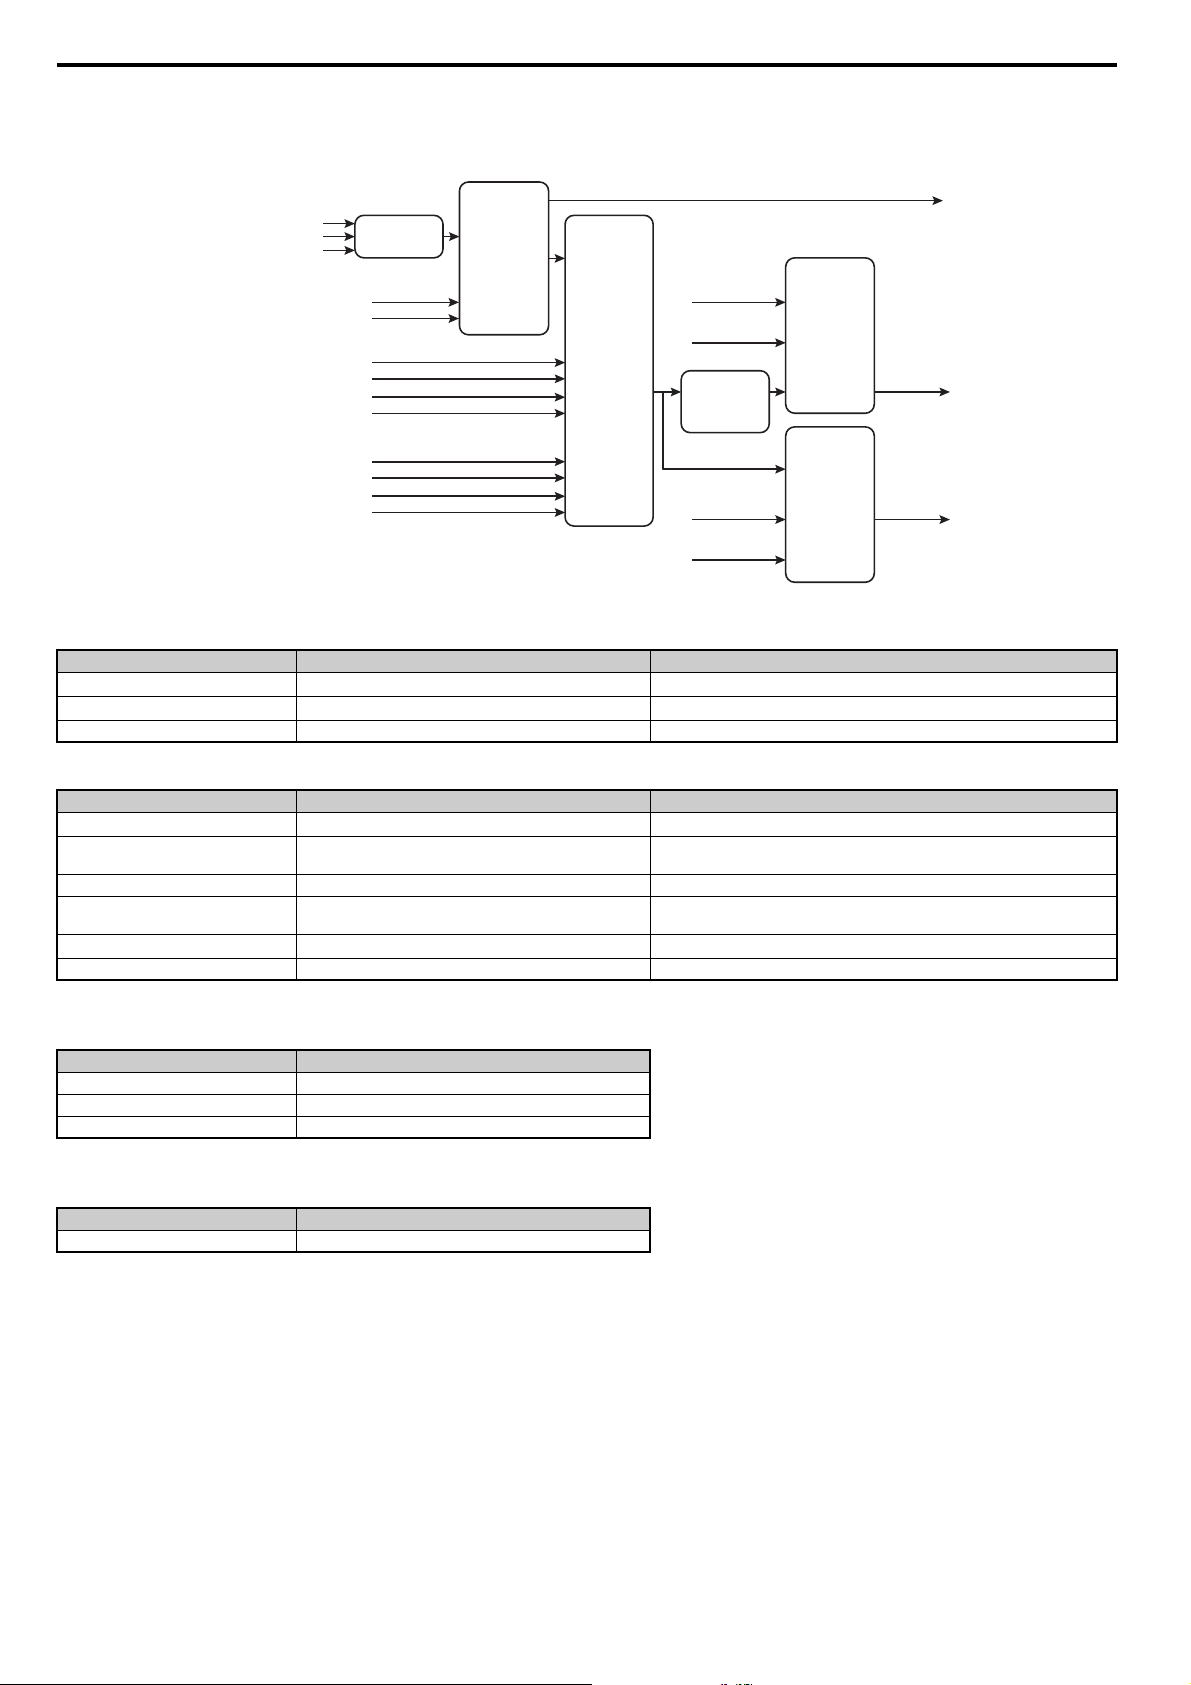
CANopen DSP402 Control Word/Status Word
This section describes how to control the drive via control word/status word and how to access drive parameters.
Figure 7
Note: The bits 4 - Enable Ramp, 5 - Unlock Ramp and 6 - Reference Ramp must be set.
Table 8 Control Word
Bit Number Control Word Application Reference/CPI Function Calls
0 - 3, 7 -
4 - 6 Operation mode specific
8 - 15 Reserved NA
These bits control the DS402 state machine - See
Please see
Ta bl e 8 for more details
Ta bl e 12
Tab l e 9 St a tus Wo r d
Bit Number Status Word Inverter Reference
0 - 6 -
7 Warning
These bits control the DS402 state machine - See
1: Warning is present.
0: No warning is present.
Ta bl e 13
8 Manufacturer specific NA
9 Remote
10 Target reached (Op mode spec)
1: Inverter uses NET cmd or ref
0: Inverter does not use NET cmd or ref
Table 11
See
11 - 15 Reserved NA
Control Word Operation Mode Specific Bits in Velocity Mode
Table 10 Control Word Operation Mode Specific Bits in Velocity Mode
Bit Number Control Word
4 RFG enable
5 RFG unlock
6 RFG use ref
Status Word Operation Mode Specific Bits in Velocity Mode
Table 11 Status Word Operation Mode Specific Bits in Velocity Mode
Bit Number Status Word
10 Target reached
16 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 17
7 DSP301 and DSP402 Specifications
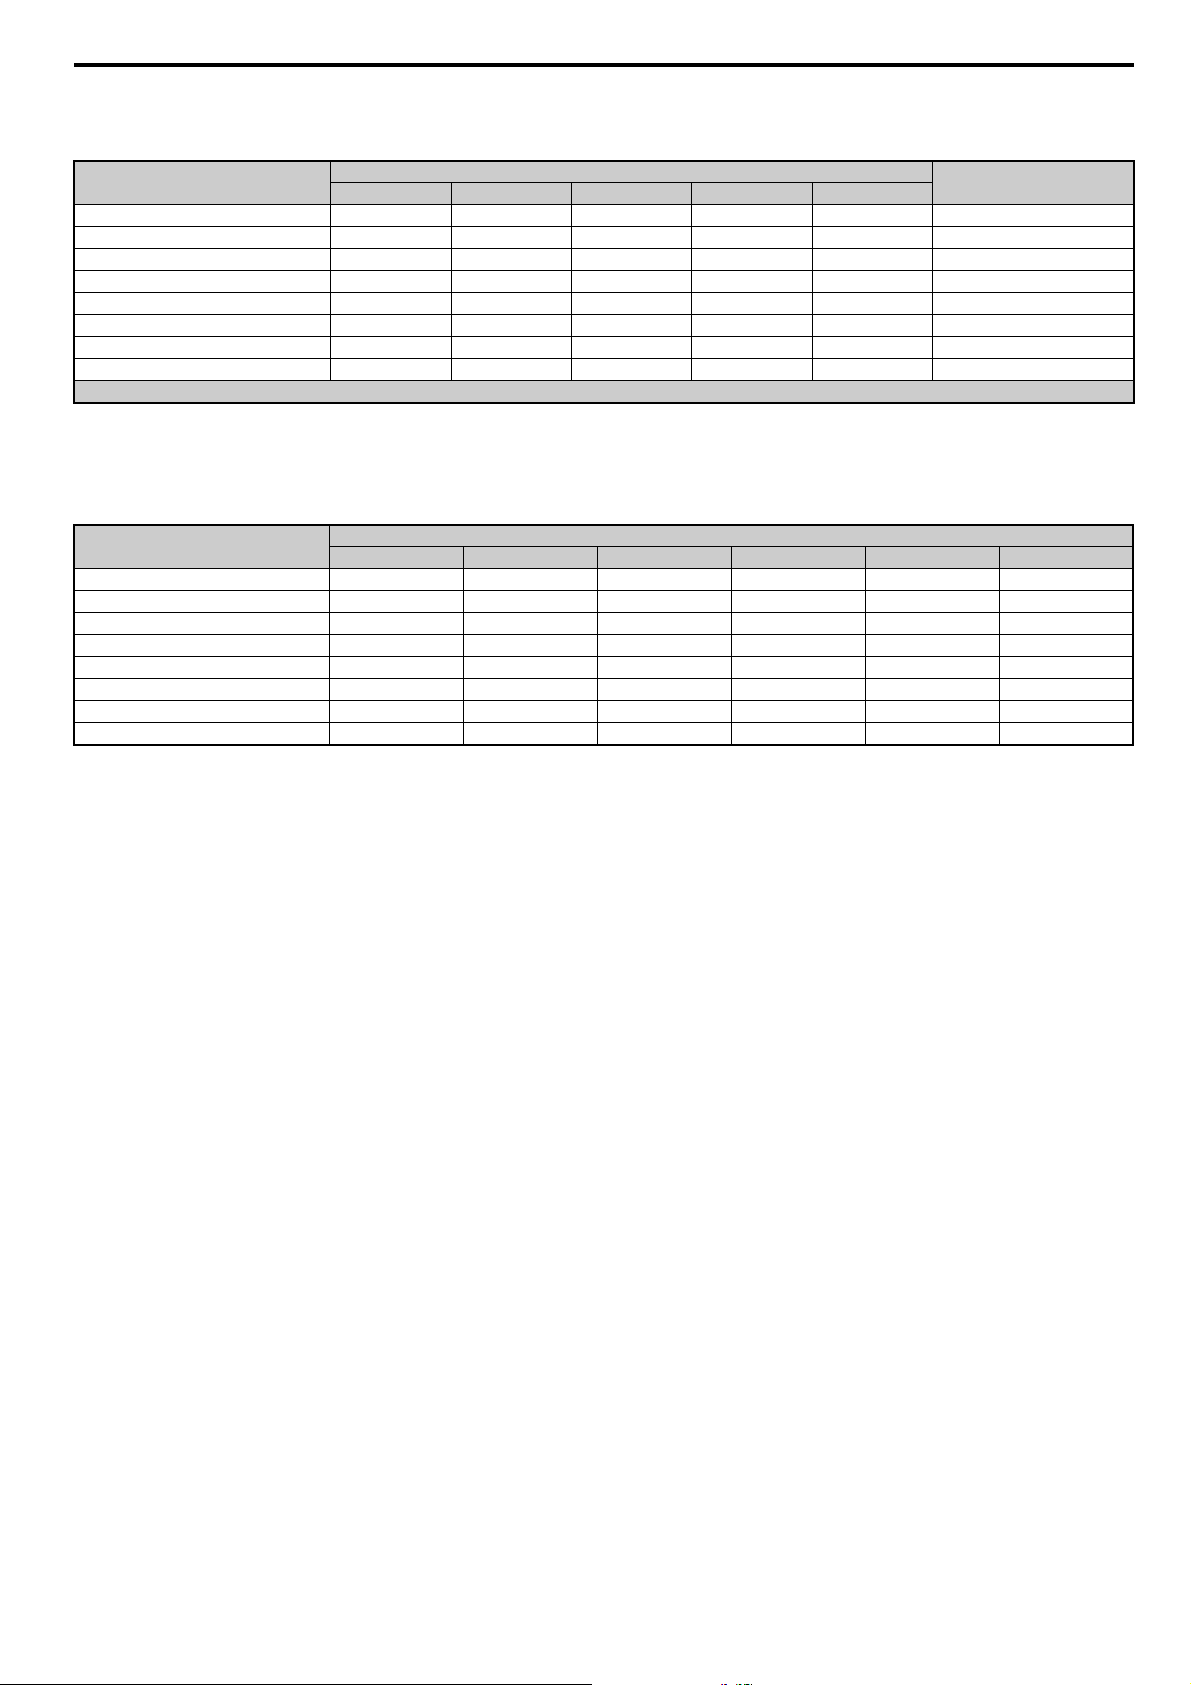
CANopen DSP402 Control Word State Transition Bits
Table 12 Control Word State Transitions
DSP402 Command
0: Shutdown 0 X 1 1 0 2,6,8
1: Switch on 0 0 1 1 1 3
2: Switch on + enable operation 0 1 1 1 1 3 + 4 (NOTE 1)
3: Disable voltage 0 X X 0 X 7,9,10,12
4: Quick stop 0 X 0 1 X 7,10,11
5: Disable operation 0 0 1 1 1 5
6: Enable operation 0 1 1 1 1 4,16
7: Fault reset 0 -> 1XXXX 15
Notes: 1. Automatic transition to Enable operation state after executing SWITCHED ON state functionality.
Bit 7 Bit 3 Bit 2 Bit 1 Bit 0
CANopen DSP402 Status Word State Transition Bits
After a change in the control word (remote control) according to Table 11 the node state will change and the state result will be indicated in the
status word according to Table 12.
Table 13 Status Word State Transitions
DSP402 State
1: Not ready to switch on 0 X 0 0 0 0
2: Switch on disabled 1 X 0 0 0 0
3: Ready to switch on 0 1 0 0 0 1
4: Switched on 0 1 0 0 1 1
5: Operation enabled 0 1 0 1 1 1
6: Quick stop active 0 0 0 1 1 1
7: Fault reaction active 0 X 1 1 1 1
8: Fault 0 X 1 0 0 0
Bit 6 Bit 5 Bit 3 Bit 2 Bit 1 Bit 0
Bits of the Control Word
Bits of the status word
Transitions
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 17
Page 18
8 Object Dictionary
8 Object Dictionary
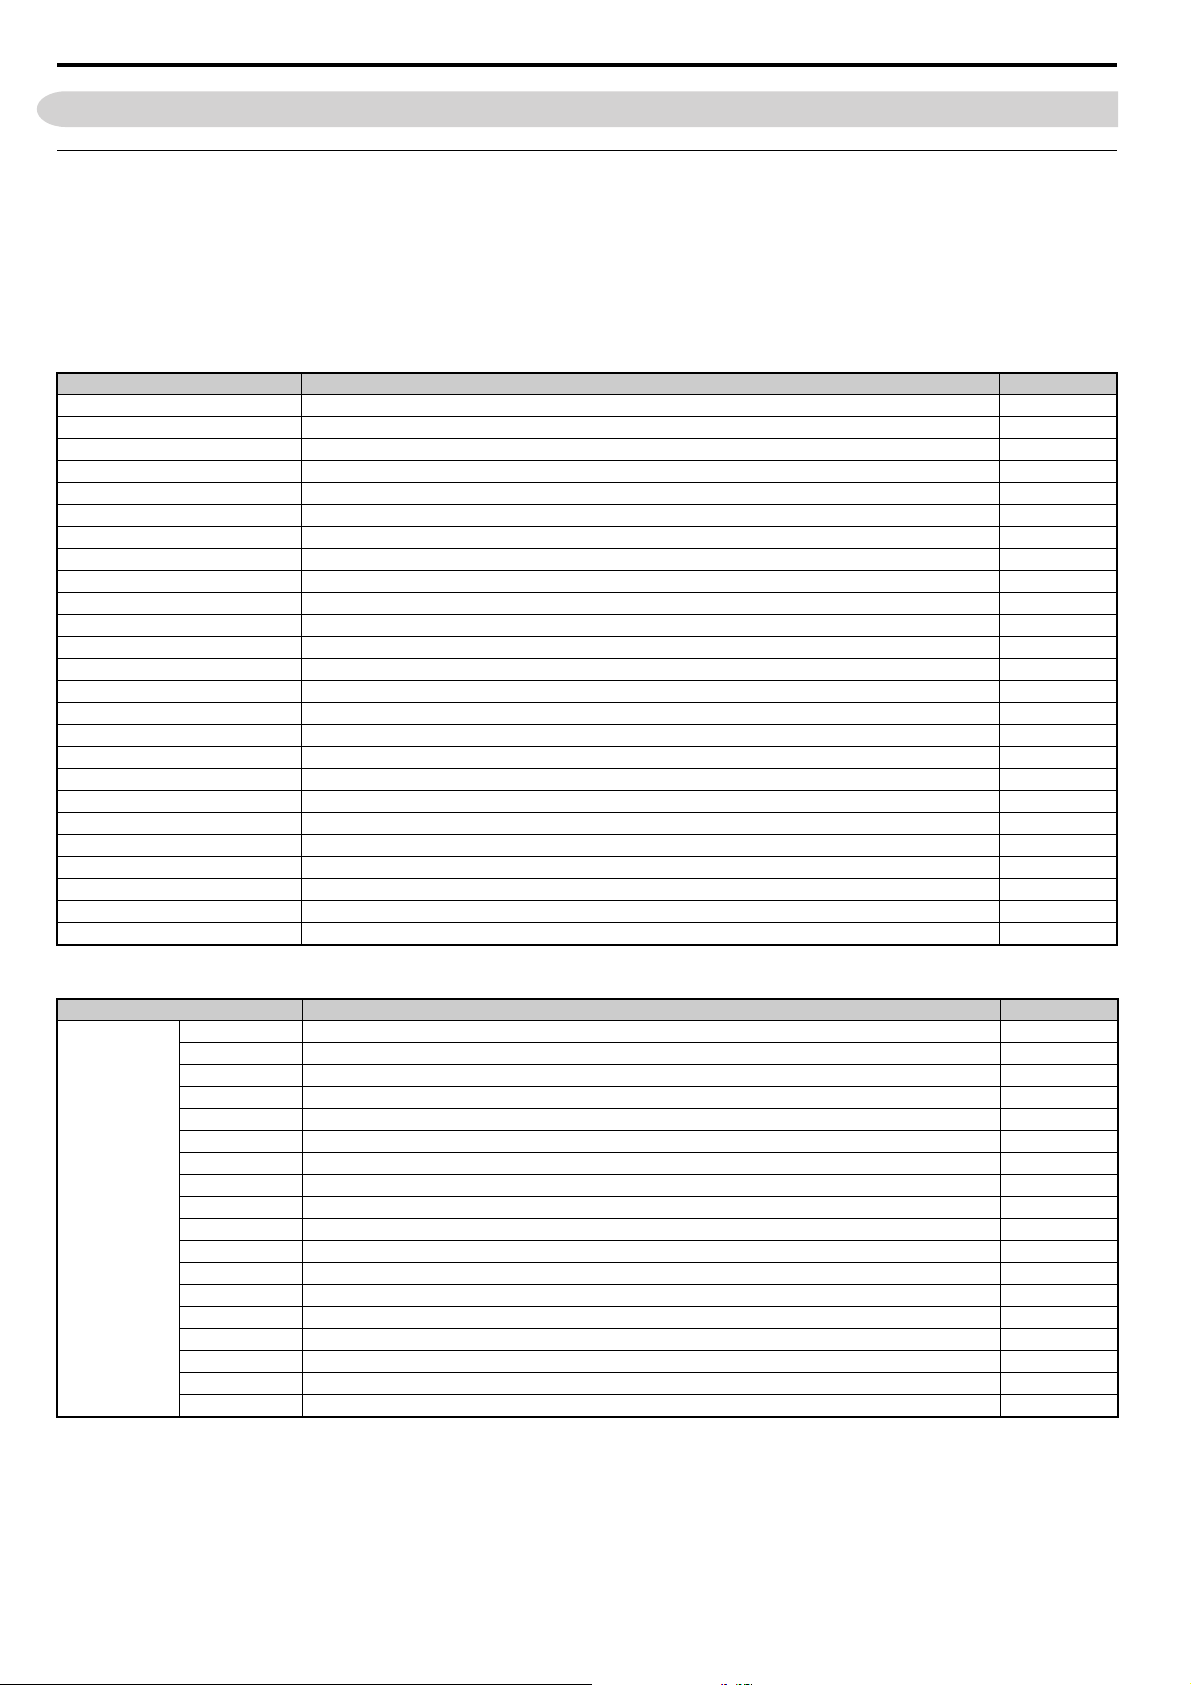
Object Dictionary Overview
The Object Dictionary consists of three sections:
• Communication Profile Objects
• Manufacturer Specific Profile Objects
• Drive and Motion Profile Objects
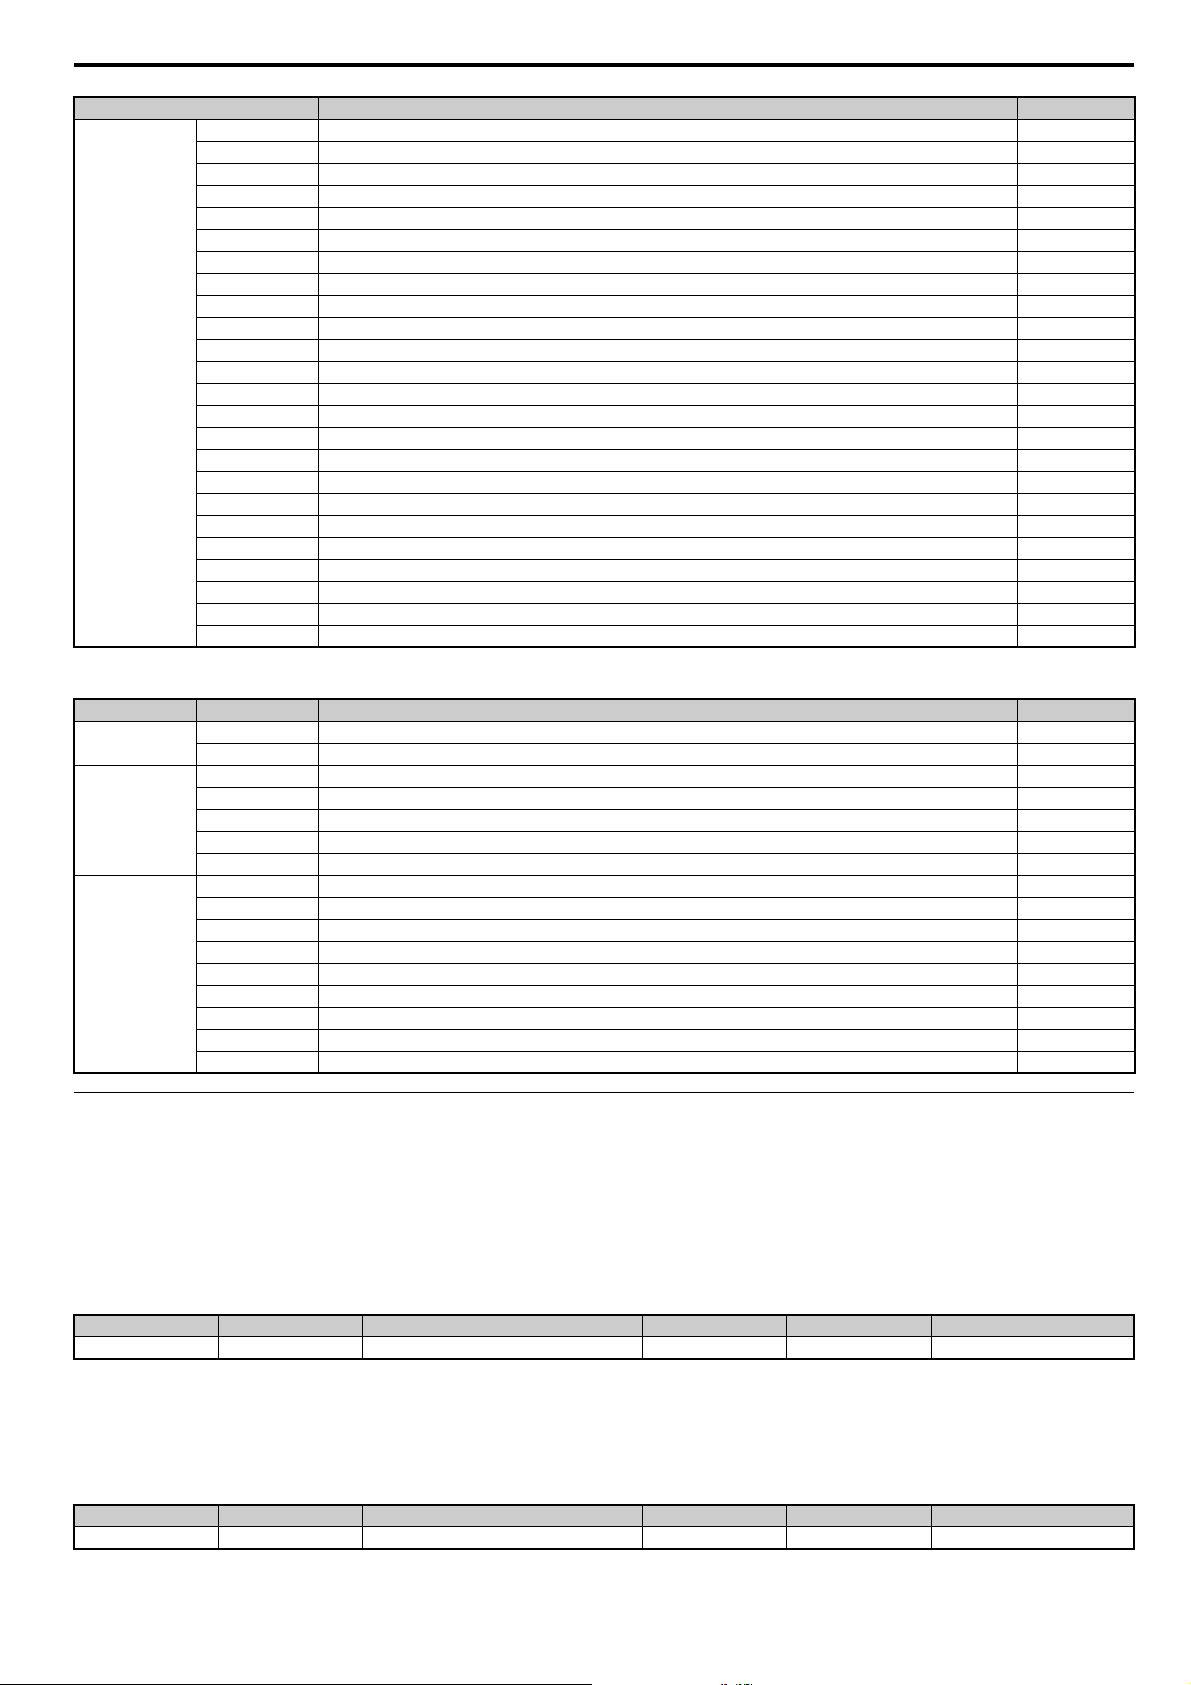
The tables below give an overview of the communication objects available in the SI-EL3 option. Refer to the page references given for further
details on each object.
Communication Profile Objects (DSP 301)
Index (Hex) Name Page
1000 Device Type 19
1001 Error Register 19
1003 Pre-defined Error Field 20
1006 NMT Cycle Time 20
1008 Manufacturer Device Name 20
1009 Manufacturer Hardware Version 20
100A Manufacturer Software Version 20
1018 Identity Object 20
1020 Device Local Configuration Date and Time 20
1030 Network Interface Parameters 21
1300 SDO Sequence Layer Timeout 21
1400 Receive PDO Communication Parameters 21
1600 - 1628 Receive PDO Mapping 21
1800 Receive PDO Communication Parameters 21
1A00 Transmit PDO mapping 21
1C0B Loss of SoC 22
1C0D Loss of PReq 22
1C0F CRC Error 22
1C14 Loss of SoC Tolerance Interval 22
1F82 Feature Flags 22
1F83 EPL Version 22
1F8C NMT Current State 22
1F93 EPL Node ID 22
1F98 NMT Cycle Timing 22
1F99 Basic Ethernet Timeout 23
Manufacturer Specific Profile Objects (DS 301)
Index (Hex) Content Page
2000 Operation Command 23
2010 Speed Command 23
2020 Torque Limit 23
2030 Torque Compensation 23
2040 MEMOBUS/Modbus Read Command 24
2050 MEMOBUS/Modbus Write Command 24
2060 MEMOBUS/Modbus Unlimited Enter Command 24
2070 MEMOBUS/Modbus Limited Enter Command 24
Input
2080 Selectable (default: none) 24
2090 Selectable (default: none) 24
20A0 Selectable (default: none) 24
20B0 Selectable (default: none) 24
20C0 Selectable (default: none) 24
20D0 FM analog output 1 25
20E0 AM analog output 2 25
20F0 Multi-function DO output 25
3000 Selectable (default: none) 24
3100 Selectable (default: none) 24
18 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 19
8 Object Dictionary
Index (Hex) Content Page
2100 Drive Status 25
2110 Output Frequency 25
2120 Output Current 25
2130 Output Torque 26
2140 MEMOBUS/Modbus Read Command Response 26
2150 MEMOBUS/Modbus Write Command Response 26
2155 PDO Parameter Write Response 26
2160 MEMOBUS/Modbus Not Limited Enter Command Response 26
2180 Selectable (default: Input terminal status) 26
2190 Selectable (default: Analog input 1 monitor) 26
21A0 Selectable (default: none) 26
Output
21B0 Selectable (default: none) 26
21C0 Selectable (default: none) 26
21E0 Selectable (default: none) 26
21D0 Selectable (default: none) 26
21F0 Selectable (default: none) 26
2200 Motor Speed 27
2210 DC Bus Voltage 27
2220 Analog input monitor A1 27
2240 Analog input monitor A2 27
2260 Analog input monitor A3 27
2270 Inverter DI Input 28
4000 Option NVS FATAL Record 28
4001 Option Info + Status Record 28
Drives and Motion Profile Objects (DSP 402)
Object Type Index (Hex) Name Page
Common Entries
Device Control
Velocity Mode
60FD Digital Inputs 31
60FE Digital Outputs 31
603F Error Code 29
6040 Controlword 29
6041 Statusword 29
6060 Modes of operation 30
6061 Modes of operation display 31
6042 vl target velocity 29
6043 vl velocity demand 29
6044 vl control effort 29
6046 vl velocity min max amount 29
6048 vl velocity acceleration 30
6049 vl velocity deceleration 30
604A vl velocity quick stop 30
604C vl dimension factor 30
604D vl pole number 30
Communication Profile Objects (DS 301)
1000 (Hex) - Device Type
This object describes the type of the device and its functionality. It is composed of a 16 bit field that describes the device profile used and a second
16 bit field that gives additional information about optional functionality.
Bit 0-15: Device Profile Number = 0x0192 (402) (static)
Bit 16-23: Type = x01 (static)
Bit 24-31: Mode Bits (Vendor specific) = 0x00
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
1000 – Device type Read Only No Unsigned 32
1001 (Hex) - Error Register
This register shows the fault status of the device. If any errors occurs in the device bit, 0 (generic error) is set to one.
0x00 = No error
0x01 = Generic error
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
1001 – Error register Read Only Tx Unsigned 8
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 19
Page 20
8 Object Dictionary
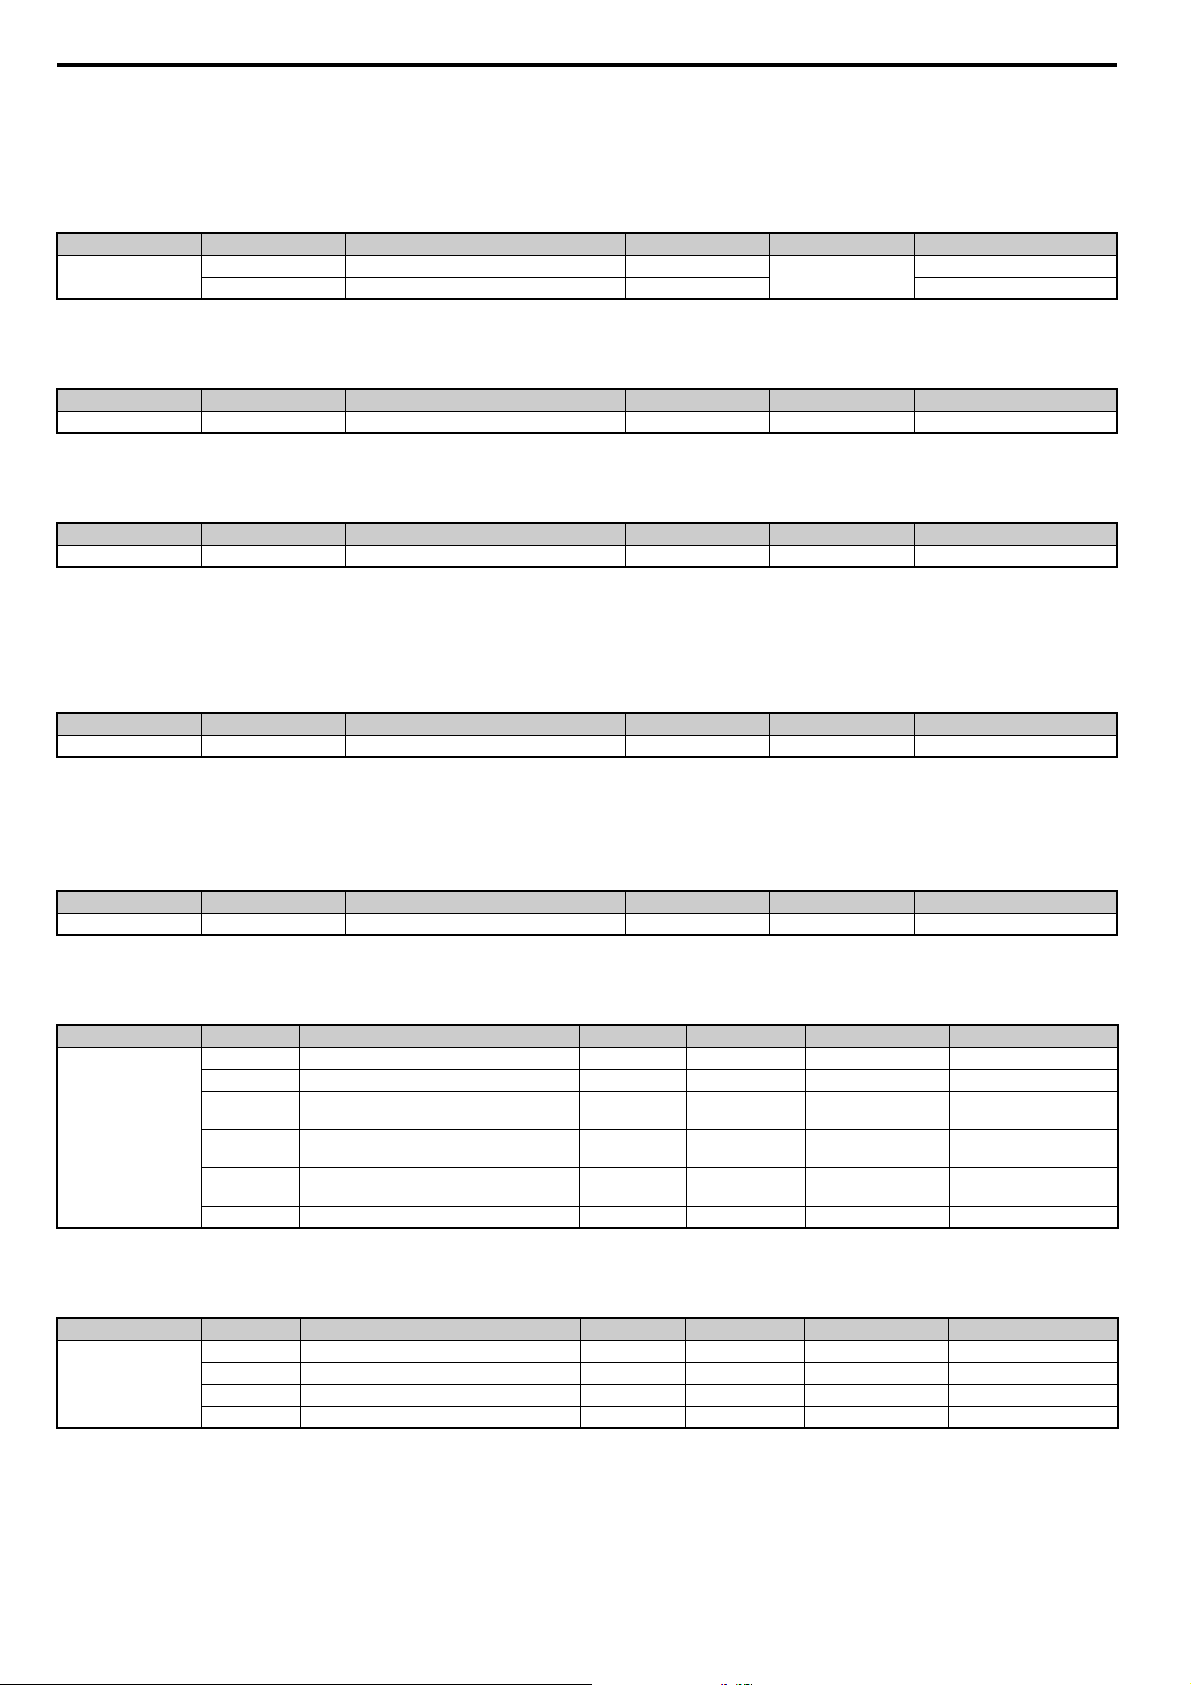
1003 (Hex) - Pre-defined Error Field
This register provides a history of errors that occurred in the drive and have been signalized via the Emergency object. Subindex 0 contains the
number of errors. Subindexes 1 to FF contain a rolling list of error codes where subindex 1 always contains the last occurring error. Refer to
Powerlink Option Card Error Codes on page 36 for a list of possible error codes. The number of valid logged errors in sub index is 0x01-0xFE.
Writing a 0 to subindex 0 resets the error field.
Index (Hex) Subindex Content Access PDO Mapping Value Range
1003
0 Number of errors Read/Write
1 Standard error field Read Only Unsigned 32
No
1006 (Hex) - NMT Cycle Time
This object contains the Powerlink communication cycle time interval.
Index (Hex) Subindex Content Access PDO Mapping Value Range
1006 – NMT Cycle Time Read/Write No Unsigned 32
1008 (Hex) - Manufacturer Device Name
This object contains the manufacturer device name. String: Powerlink
Index (Hex) Subindex Content Access PDO Mapping Value Range
1008 – Manufacturer device name Read Only No Visible string
for 1000 series.
1009 (Hex) - Manufacturer Hardware Version
This object contains the manufacturer hardware version.
Value: 1.x
x = HW revision assigned during production
Unsigned 8
Index (Hex) Subindex Content Access PDO Mapping Value Range
1009 – Manufacturer hardware version Read Only No Visible string
100A (Hex) - Manufacturer Software Version
This object contains the Manufacturer software version.
Value: VST92x101
Note: The complete Software Version is available via 1018 (Hex), subindex 3. Refer to 1018 (Hex) - Identity Object on page 20 for details.
Index (Hex) Subindex Content Access PDO Mapping Value Range
100A – Manufacturer software version Read Only No Visible string
1018 (Hex) - Identity Object
This object contains general information about the drive.
Index (Hex) Subindex Content Access PDO Mapping Val ue Value Range
- Identity object Read/Write - Unsigned 32
0 Number of entries Read Only No 4 Unsigned 8
0x010000E7
(Yaskawa Electric)
0x53454C33
(ASCII: SEL3)
1018
1 YASKAWA ETG Member Vendor ID Read Only No
2
YASKAWA Powerlink
3
4 Powerlink option serial number Read Only No Unsigned 32
Powerlink
option product code
option software revision
number
Read Only No
Read Only No 9243.xxyy Unsigned 32
1020 (Hex) - Device Local Configuration Date and Time
This object contains configuration information about the drive.
Unsigned 32
Unsigned 32
Index (Hex) Subindex Content Access PDO Mapping Value Value Range
- Device local configuration date and time - - -
1020
20 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
0 Number of entries Read Only No 2 Unsigned 8
1 Configuration Date in Days Read/Write No Unsigned 32
2 Configuration Time in ms Read/Write No Unsigned 32
Page 21
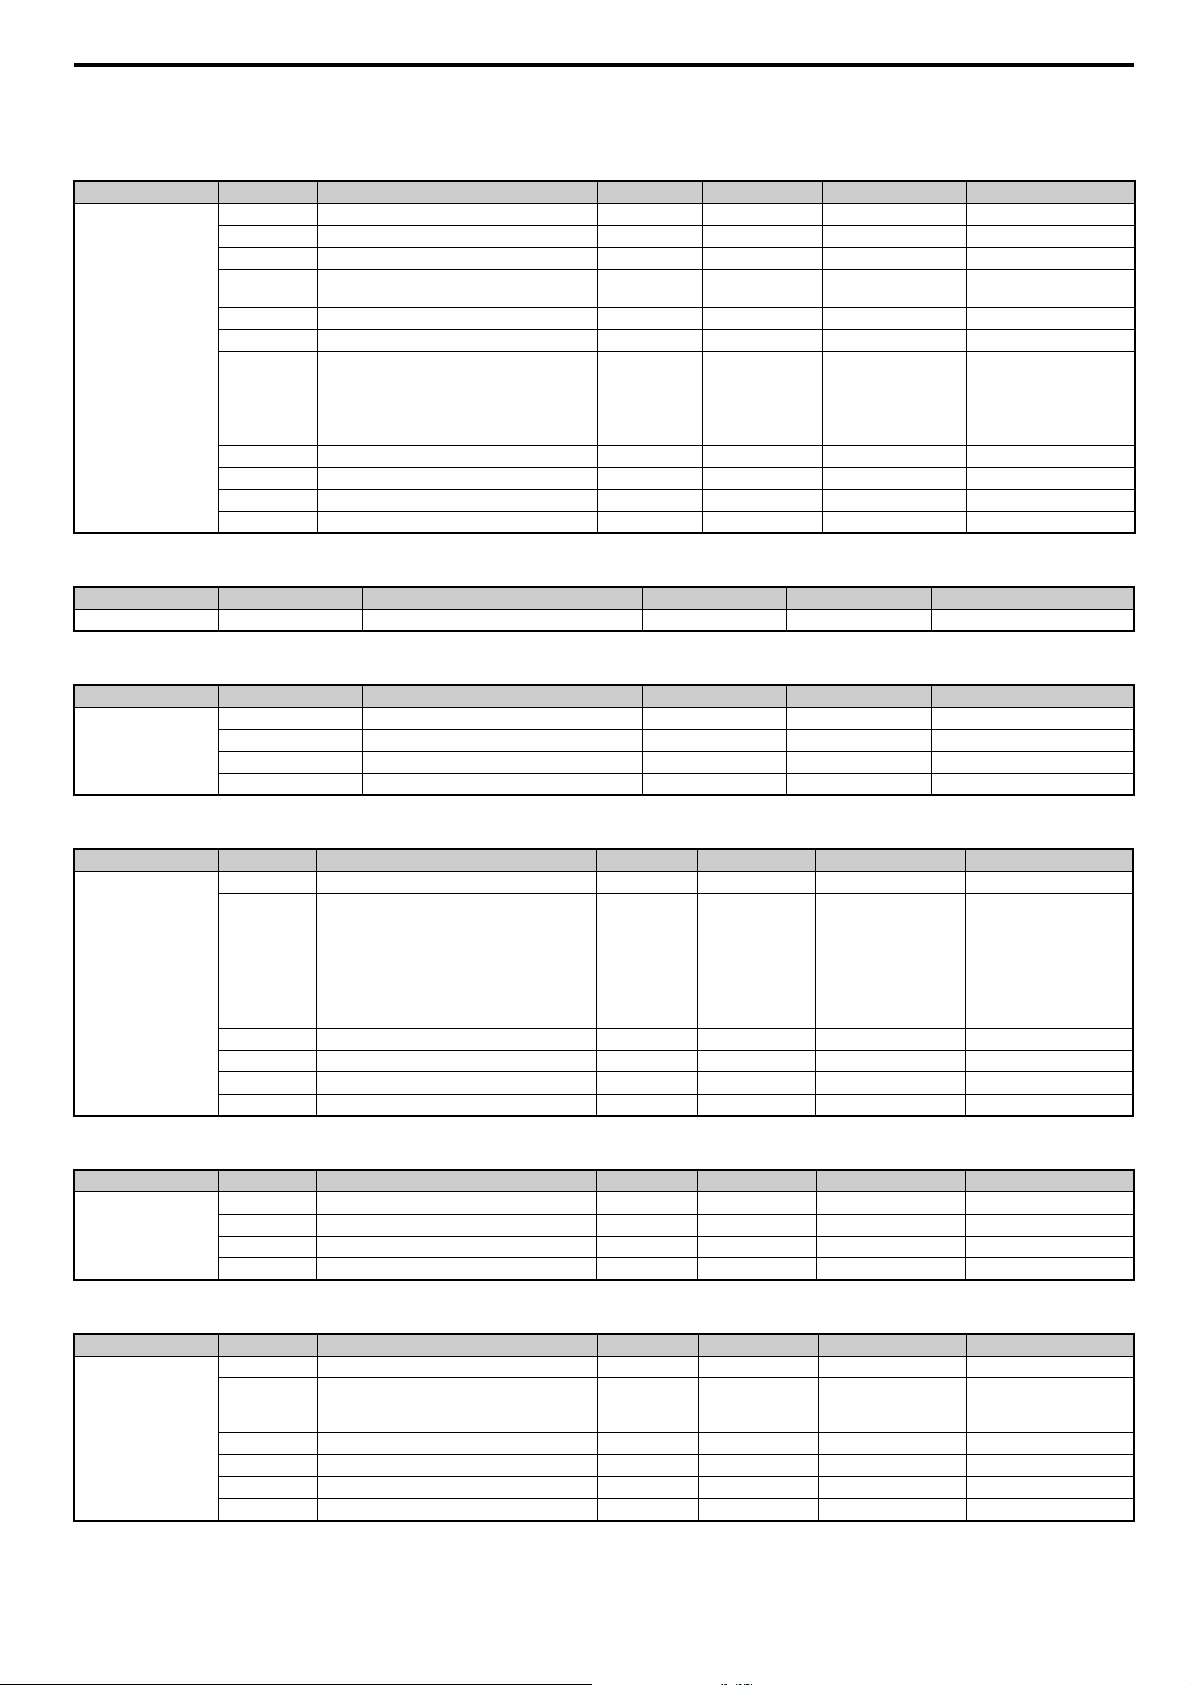
8 Object Dictionary
1030 (Hex) - Network Interface Parameters
This object contains the parameters for the network interface of the drive.
Index (Hex) Subindex Content Access PDO Mapping Value Value Range
- Network interface parameters - - -
0 Number of Entries Read Only No 9 Unsigned 8
1 Interface Index Read Only No Unsigned 16
2 Interface Description Read Only No
3 Interface Type Read Only No 6 (ethernet-csmacd) Unsigned 8
4 Interface MTU Read Only No Unsigned 16
1030
Note: The MAC address is available via
4001 (Hex) in subindex 6.
5
(Hex) - Option Info + Status Record on page 28
Interface Physical Address
Refer to 4001
Read Only No Octet string
for details.
6 Interface Name Read Only No Visible String
7 Interface Operational State Read Only No Unsigned 8
8 Interface Administration State Read/Write No Unsigned 8
9 Valid Read/Write No Boolean
1300 (Hex) - SDO Sequence Layer Timeout
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
1300 - SDO Sequence Layer Timeout Read/Write No Unsigned 32
YEU POWERLINK for
1000 series 1.x
Visible String
1400 (Hex) - Receive PDO Communication Parameters
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
- Receive PDO communication parameters - - -
1400
0 Number of Entries Read Only No Unsigned 8
1 Node ID Read/Write No Unsigned 8
2 Mapping Version Read/Write No Unsigned 8
1600 (Hex) to 1628 (Hex) - Receive PDO mapping
Index (Hex) Subindex Content Access PDO Mapping Value Value Range
- Receive PDO mapping - - -
Number of mapped application objects (0-8(2))
For default configurations per RxPDO please
refer to section 3.9.1.
Max Sub-index:
1600
0
0x1600: 8
0x1601-0x1628: 2
Note: Write access to those objects are only
allowed in the Powerlink
1 Mapped Object #1 Read/Write No Unsigned 32
2 Mapped Object #2 Read/Write No Unsigned 32
3 Mapped Object #3 Read/Write No Unsigned 32
n Mapped Object #n Read/Write No Unsigned 32
pre-operational state.
Read/Write No 0-8 (Depends on RxPDO) Unsigned 8
1800 (Hex) - Receive PDO Communication Parameters
Index (Hex) Subindex Content Access PDO Mapping Va lu e Value Ran ge
- Receive PDO communication parameters - - -
1800
0 Number of Entries Read Only No 2 Unsigned 8
1 Node ID Read/Write No Unsigned 8
2 Mapping Version Read/Write No Unsigned 8
1A00 (Hex) - Transmit PDO Mapping
Index (Hex) Subindex Content Access PDO Mapping Va lue Value Range
- Transmit PDO mapping - - -
Number of mapped application objects (0-16)
Note: Write access to those objects are only
1A00
0
allowed in the Powerlink
1 Mapped Object #1 Read/Write No Unsigned 32
2 Mapped Object #2 Read/Write No Unsigned 32
3 Mapped Object #3 Read/Write No Unsigned 32
n Mapped Object #n Read/Write No Unsigned 32
pre-operational state.
Read/Write No
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 21
0-16
(Depends on TxPDO)
Unsigned 8
Page 22
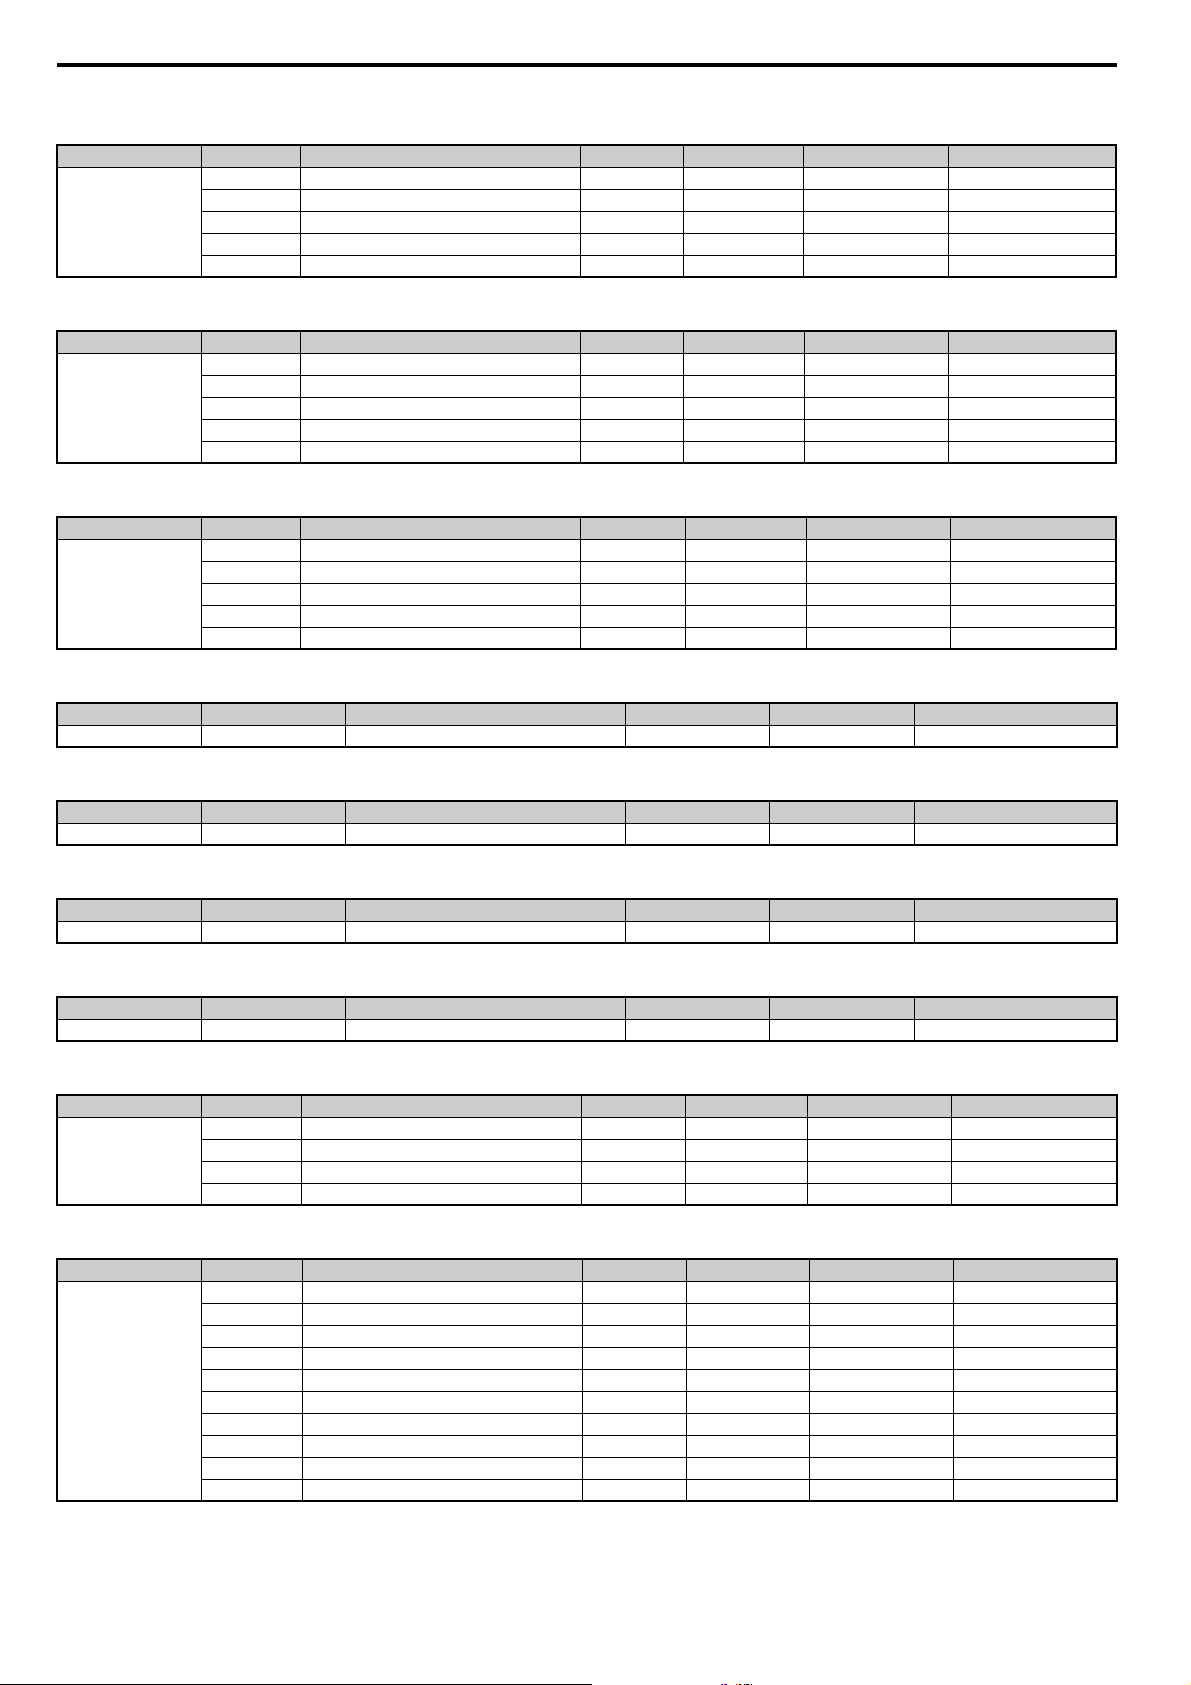
8 Object Dictionary
1C0B (Hex) - Loss of SoC
Index (Hex) Subindex Content Access PDO Mapping Valu e Value Range
- Loss of SoC - - -
0 Number of Entries Read Only No 3 Unsigned 8
1C0B
1C0D (Hex) - Loss of PReq
Index (Hex) Subindex Content Access PDO Mapping Value Valu e R an ge
1C0D
1C0F (Hex) - CRC Error
Index (Hex) Subindex Content Access PDO Mapping Valu e Val ue R an ge
1C0D
1 Cumulative Counter Read/Write No Unsigned 32
2 Threshold Counter Read Only No Unsigned 32
3 Threshold Read/Write No Unsigned 32
- Loss of PReq - - -
0 Number of Entries Read Only No 3 Unsigned 8
1 Cumulative Counter Read/Write No Unsigned 32
2 Threshold Counter Read Only No Unsigned 32
3 Threshold Read/Write No Unsigned 32
- CRC Error - - -
0 Number of Entries Read Only No 3 Unsigned 8
1 Cumulative Counter Read/Write No Unsigned 32
2 Threshold Counter Read Only No Unsigned 32
3 Threshold Read/Write No Unsigned 32
1C14 (Hex) - Loss of SoC Tolerance Interval
Index (Hex) Subindex Content Access PDO Mapping Value Range
1C14 Loss of SoC Tolerance Interval Read/Write No Unsigned 32
1F82 (Hex) - Feature Flags
Index (Hex) Subindex Content Access PDO Mapping Value Range
1F82 Feature Flags Read Only No Unsigned 32
1F83 (Hex) - EPL Version
Index (Hex) Subindex Content Access PDO Mapping Value Range
1F83 Loss of SoC Tolerance Interval Read Only No Unsigned 8
1F8C (Hex) - NMT Current State
Index (Hex) Subindex Content Access PDO Mapping Value Range
1F8C NMT Current State Read Only Tx Unsigned 8
1F93 (Hex) - EPL Node ID
Index (Hex) Subindex Content Access PDO Mapping Value Value Range
- EPL Node ID - - -
1F93
0 Number of entries Read Only No 2 Unsigned 8
1 Node ID Read Only No Unsigned 6
2 Node ID by HW Read Only No Boolean
1F98 (Hex) - NMT Cycle Timing
Index (Hex) Subindex Content Access PDO Mapping Va lue Va lue Ra ng e
- NMT Cycling Timing - - -
0 Number of entries Read Only No 8 Unsigned 8
1 Isochronous Tx max payload Read Only No Unsigned 16
2 Isochronous Rx max payload Read Only No Unsigned 16
1F98
22 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
3 PRes max latency Read Only No Unsigned 32
4 PReq actual payload limit Read/Write No Unsigned 16
5 PRes actual payload limit Read/Write No Unsigned 16
6 ASnd max latency Read Only No Unsigned 32
7 Multiplexed cycle count Read/Write No Unsigned 8
8 Asynchronous MTU Read/Write No Unsigned 16
Page 23
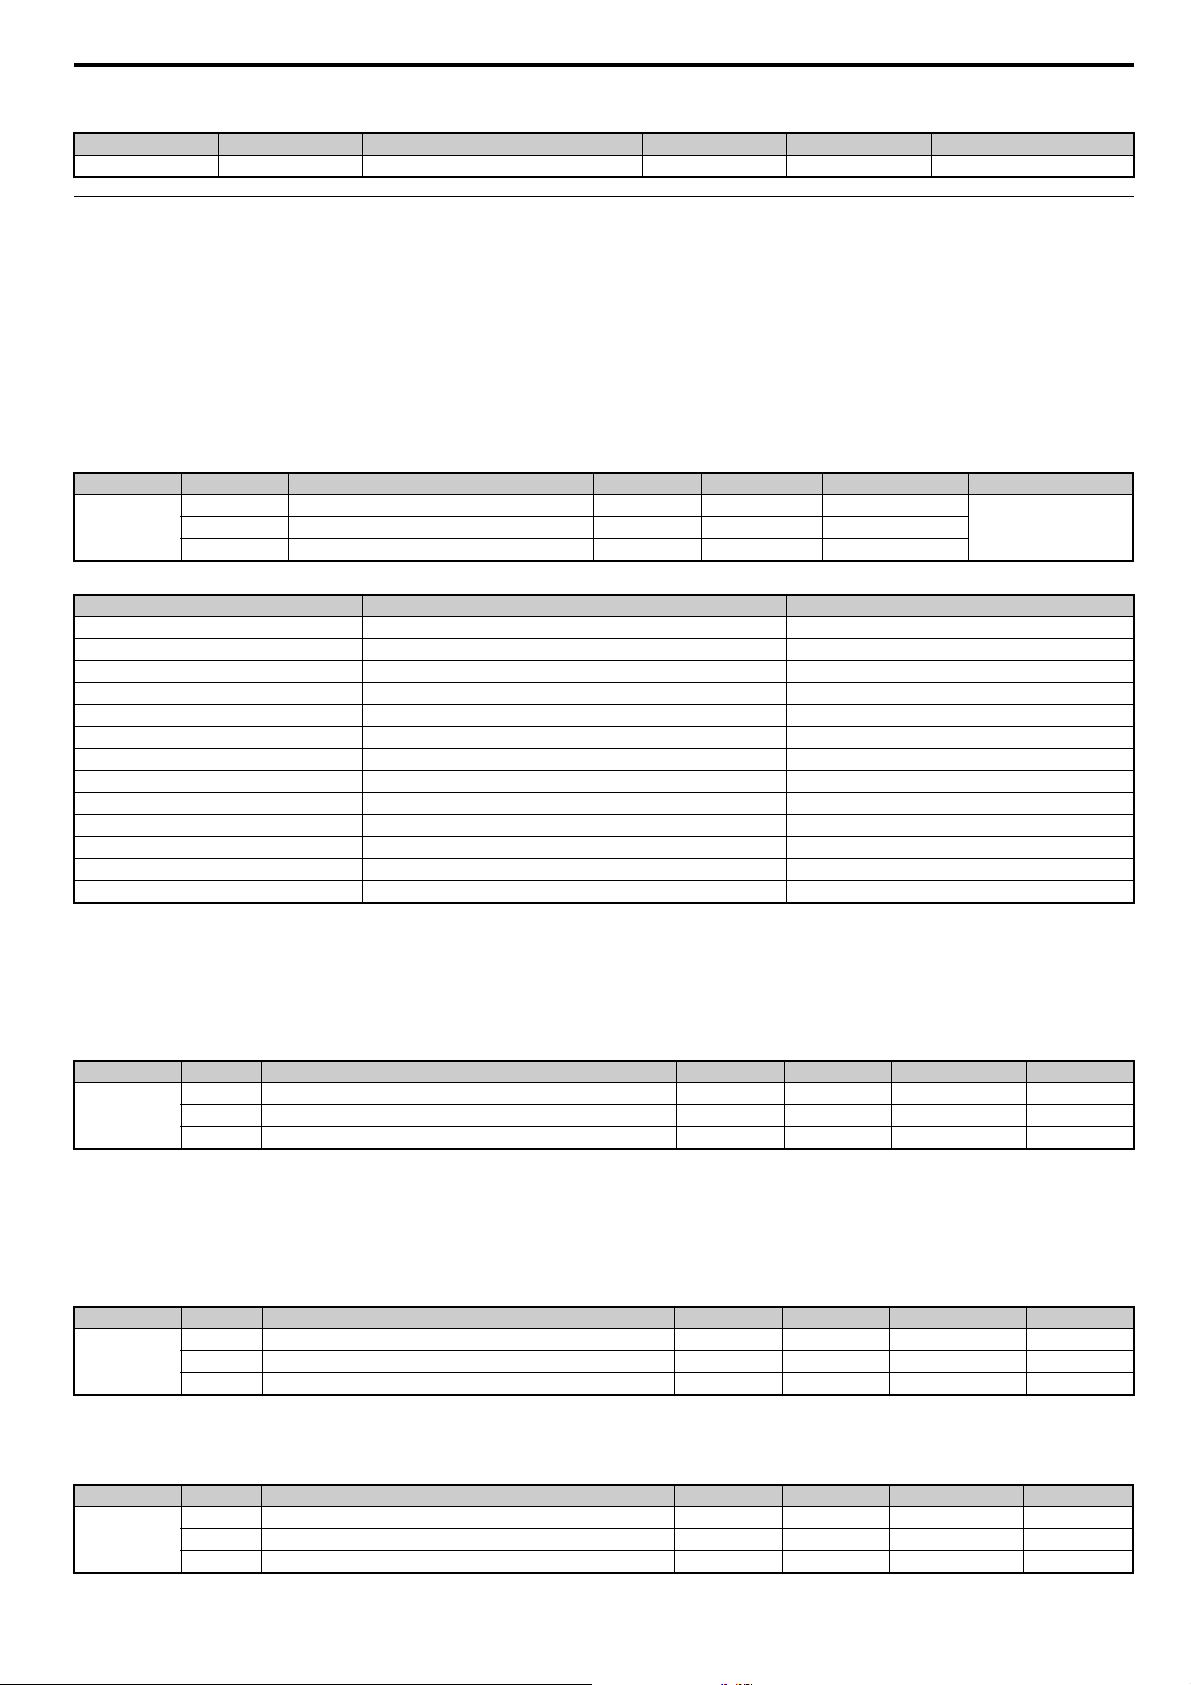
8 Object Dictionary
1F99 (Hex) - Basic Ethernet Timeout
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
1F99 Basic Ethernet Timeout Read/Write Tx Unsigned 32
Manufacturer Specific Profile Objects (DS 301)
The SI-EL3 option offers the manufacturer specific objects listed below. These objects are specific to Yaskawa products and are therefore not
available on other Powerlink products.
The manufacturer specific objects list consists of objects that have predefined, non-changeable content and objects that are configurable. The
content of configurable objects can be determined by linking these objects to drive parameters, monitors or MEMOBUS/Modbus registers (refer to
Selectable Object Content on page 32).
Input objects are processed in a cycle of 2 ms. Output objects are, depending on the object, updated in a cycle of either 2 ms or 8 ms. The update
cycle cannot be changed.
2000 (Hex) - Operation Command
This object is used for starting and stopping the drive, for controlling the multi-function digital input terminals, as well for triggering and resetting faults.
Index (Hex) Subindex Content Access PDO Mapping Val ue Data Length
0 Operation Command Read/Write Possible
2000
2 MEMOBUS/Modbus register address Read Only No Run operation signal
Bit No. (Hex) Description Function
0 Forward Run 1: Forward run, 0: Stop (Enabled when b1-02=3)
1 Reverse Run 1: Reverse run, 0: Stop (Enabled when b1-02=3)
2 External Fault (EF0) 1: External Fault Input (EF0)
3 Fault Reset 1: Fault Reset
4 Terminal S1 Function Multi-Function Input: H1-01
5 Terminal S2 Function Multi-Function Input: H1-02
6 Terminal S3 Function Multi-Function Input: H1-03
7 Terminal S4 Function Multi-Function Input: H1-04
8 Terminal S5 Function Multi-Function Input: H1-05
9 Terminal S6 Function Multi-Function Input: H1-06
10 Terminal S7 Function Multi-Function Input: H1-07
11 Terminal S8 Function Multi-Function Input: H1-08
12 to 15 Not used Not used
2 byte1 Value Read/Write Rx/Tx
2010 (Hex) - Speed Reference/Speed Limit
Sets the speed reference or speed limit. The unit of this value depends on the setting of the drive parameter o1-03 (0 = Hz; 1 = % with 100% equals
parameter E1-04; 2 = rev/min with the motor poles number entered into E2-04/E4/04/E5-04; 3 = user defined parameters o1-10 and 01-11.
The value will be used as the speed reference for speed control (d5-01 = 0) or as the speed limit in torque control (d5-01 = 1).
Note: The availability of the torque control function depends on the drive and the selected control mode. For details refer to the technical manual for the
drive.
Index (Hex) Subindex Content Access PDO Mapping Va lu e Data Length
0 Number of entries Read/Write Possible 2 byte
2010
1 Value Read/Write Rx/Tx Frequency reference -
2 MEMOBUS/Modbus register address Read Only No -
2020 (Hex) - Torque Reference/Torque Limit
This object sets the torque reference or the torque limit in units of 0.1%.
In order to use this object set drive parameter F6-06 to 1. The value will be used as the torque reference for torque control (d5-01 = 1) or as the
torque limit in speed control (d5-01 = 0).
Note: The availability of the torque control and torque limit function depends on the drive and the selected control mode. For details refer to the technical
manual for the drive.
Index (Hex) Subindex Content Access PDO Mapping Val ue Data Length
0 Number of entries Read/Write Possible 2 byte
2020
1 Value Read/Write Rx Tx Torque ref/limit -
2 MEMOBUS/Modbus register address Read Only No -
2030 (Hex) - Torque Compensation
This object sets the torque compensation in units of 0.1%.
Index (Hex) Subindex Content Access PDO Mapping Data Length
0 Torque Compensation Read/Write Possible 2 byte
2030
1 Value Read/Write Rx Tx Torque compensation -
2 MEMOBUS/Modbus register address Read Only No -
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 23
Page 24
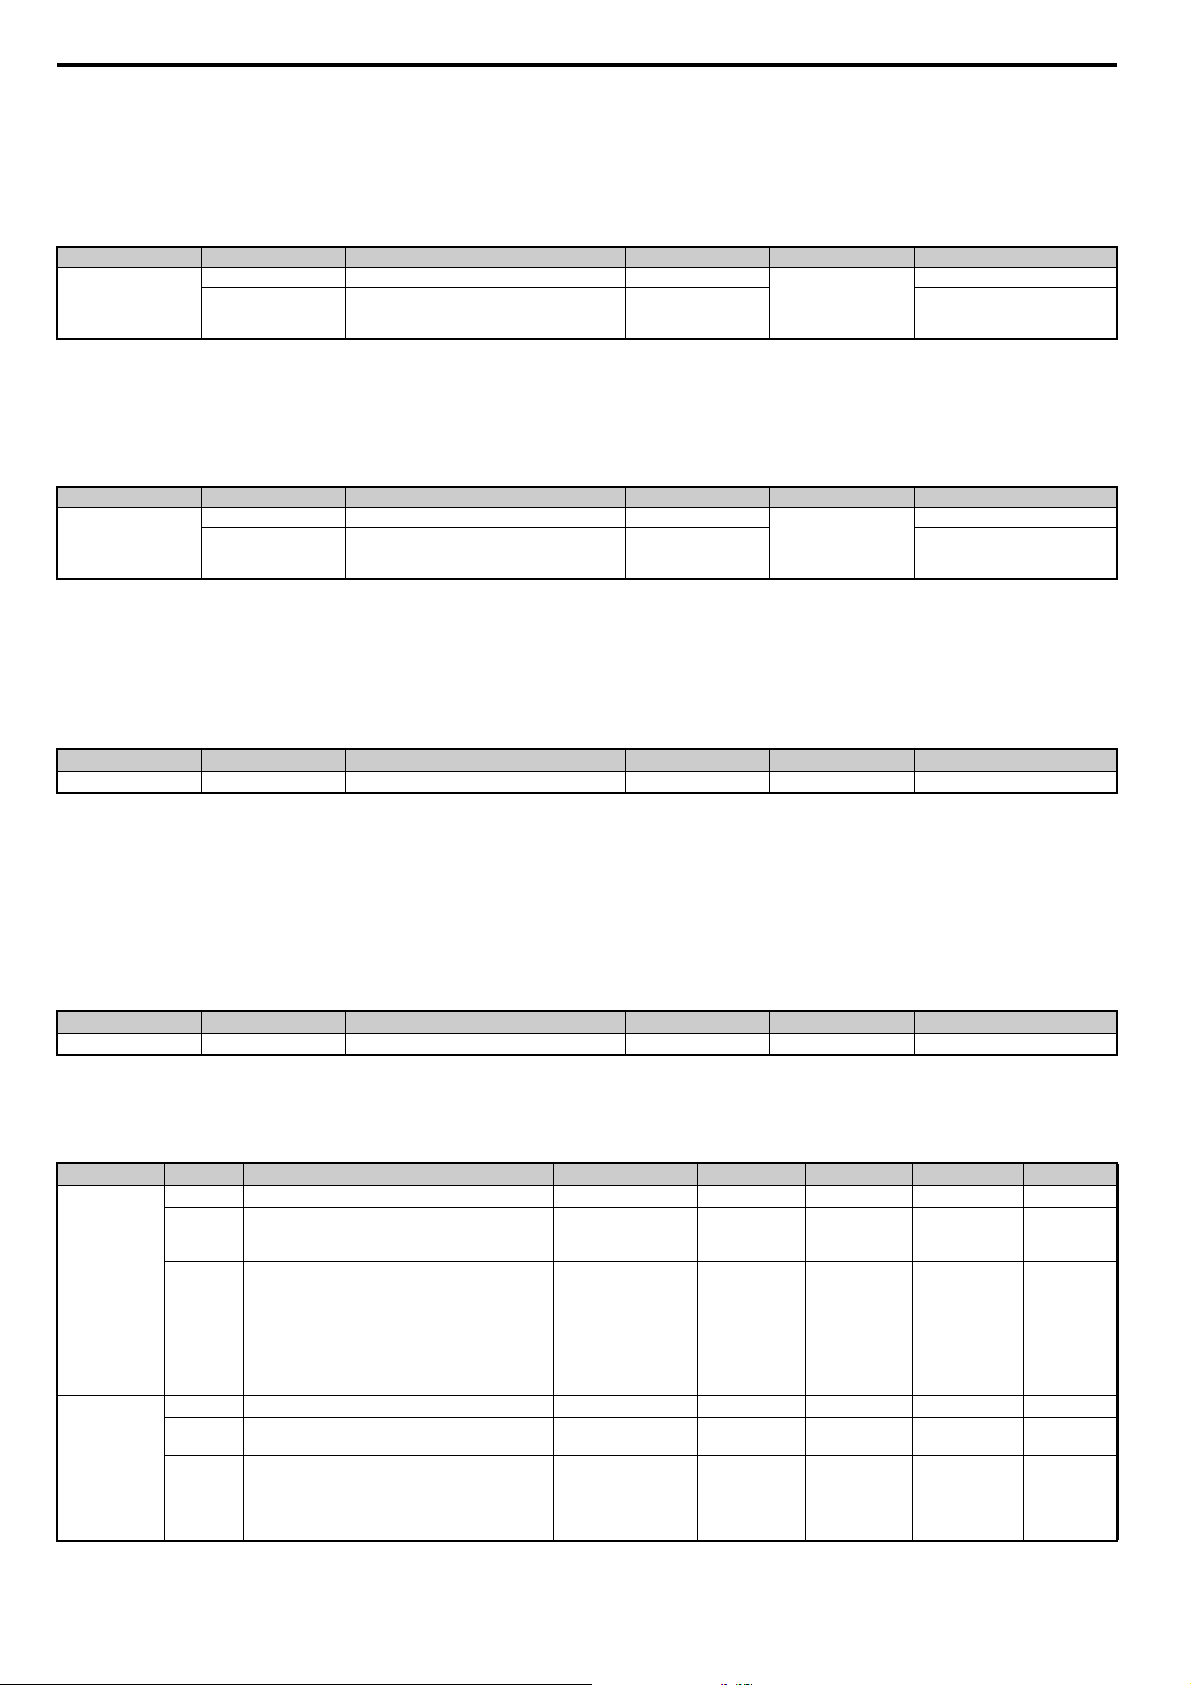
8 Object Dictionary
2040 (Hex) - MEMOBUS/Modbus Read Request
This object can be used to read out the content of drive MEMOBUS/Modbus registers. The address of the MEMOBUS/Modbus must be written in
byte 3 and 4 of Subindex 1, bytes 1 and 2 have to be set to 0. After sending a MEMOBUS/Modbus Read Request to the drive, the MEMOBUS/
Modbus register content can be read out from object 2140H.
For more details on MEMOBUS/Modbus address and data, refer to the MEMOBUS/Modbus/Modbus Data Table in Appendix C of the technical
manual for the drive.
Index (Hex) Subindex Content Access PDO Mapping Data Length
0 Number of entries Read Only
2040
1 MEMOBUS/Modbus read request Read/Write
Possible
2050 (Hex) - MEMOBUS/Modbus Write Request
Using this object, drive MEMOBUS/Modbus registers can be written. The data must be written in byte 1 and 2 of Subindex 1, the MEMOBUS/
Modbus address must be written in bytes 3 and 4. After sending a MEMOBUS/Modbus Write Request to the drive, the response can be read from
object 2150H.
For more details on MEMOBUS/Modbus address and data, refer to the MEMOBUS/Modbus Data Table in Appendix C of the technical manual for the drive.
Index (Hex.) Subindex Content Access PDO Mapping Data Length
0 Number of entries Read Only
2050
1 MEMOBUS/Modbus Write request Read/Write
Possible
2060 (Hex) - MEMOBUS/Modbus Unlimited ENTER Command
Depending on the drive parameter H5-11 setting, an ENTER command must be used to activate drive parameters changed via MEMOBUS/Modbus
Write Commands. The Unlimited ENTER command activates parameters in the drive RAM only. If the drive power is cycled, parameter changes
are lost. If more than one parameter has been changed, it is enough to send only one ENTER command after the last parameter change. Doing so
will activate all changed parameters. This ENTER command can be used without limitations.
To execute this type of ENTER command, “save” (73H + 61H + 76H + 65H) has to be written in object 2060H, subindex 0.
1 byte
2 + 2 byte
MEMOBUS/Modbus
0000H + Address
1 byte
2 + 2 byte
MEMOBUS/Modbus
Data + Address
Index (Hex) Subindex Content Access PDO Mapping Data Length
2060 - Unlimited ENTER command Read/Write Possible 4 byte
2070 (Hex) - MEMOBUS/Modbus Limited ENTER Command
Depending on the drive parameter H5-11 setting, an ENTER command must be used to activate drive parameters changed via MEMOBUS/Modbus
Write Commands. The limited ENTER command activates parameters in the drive’s RAM and saves them to the EEPROM. When power supply
loss occurs or the power supply is cycled, the drive will operate using the saved parameters. If more than one parameter has been changed, it is
sufficient to send only one ENTER command after the last parameter change. Doing so will activate all changed parameters. This type of ENTER
command can be applied approximately 100,000 times and should be used only when necessary.
To execute this type of ENTER command, “save” (73H + 61H + 76H + 65H) has to be written in object 2070H, subindex 0.
Note: Write access to this object is only allowed in the Powerlink
Index (Hex) Subindex Content Access PDO Mapping Data Length
2070 - Limited enter command Read/Write Possible 4 byte
pre-operational state.
2080 to 3100 (Hex) - Freely Configurable Input Objects
The content of these objects can be freely selected by linking them to drive MEMOBUS/Modbus registers. Refer to Selecting the Object Content
on page 32 for details.
Index (Hex)
2080
2090 to 20C0,
3000, and 3100
<1> Read/Write access when SI-EL3/V is in the Pre-Operational state, Read only access if the SI-EL3/V is in the Operational state or if the drive is running.
Subindex Content Default Access PDO Mapping Va lu e Data Length
0 Number of entries 2 Read Only No 1 Byte
1
<1>
2
0 Number of entries 2 Read Only No 1 Byte
1
2
Value of mapped MEMOBUS register.
AAAA = MEMOBUS register 1 value
BBBB = MEMOBUS register 2 value
MEMOBUS/Modbus register address of
AAAA = MEMOBUS register 1 address
BBBB = MEMOBUS register 2 address
Reg. value=0xFFFF ' Mapping disabled.
Note: Those values can only be changed in Powerlink
pre-operational state. Refer to Table 4 for the state
relations.
Value of mapped MEMOBUS register.
AAAA = MEMOBUS register value
MEMOBUS/Modbus register address of content
AAAA = MEMOBUS register address.
Note: Those values can only be changed in Powerlink
pre-operational state. Refer to Table 4 for the state
relations.
content 1 and 2
- Read/Write Possible 0xAAAABBBB 4 byte
FFFF (Hex)/FFFF (Hex) Read/Write
- Read/Write Possible 0xAAAA 2 Byte
FFFF (Hex) Read/Write
<1> No 0xAAAABBBB 4 Byte
<1> No 0xAAAA 2 Byte
24 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 25
8 Object Dictionary
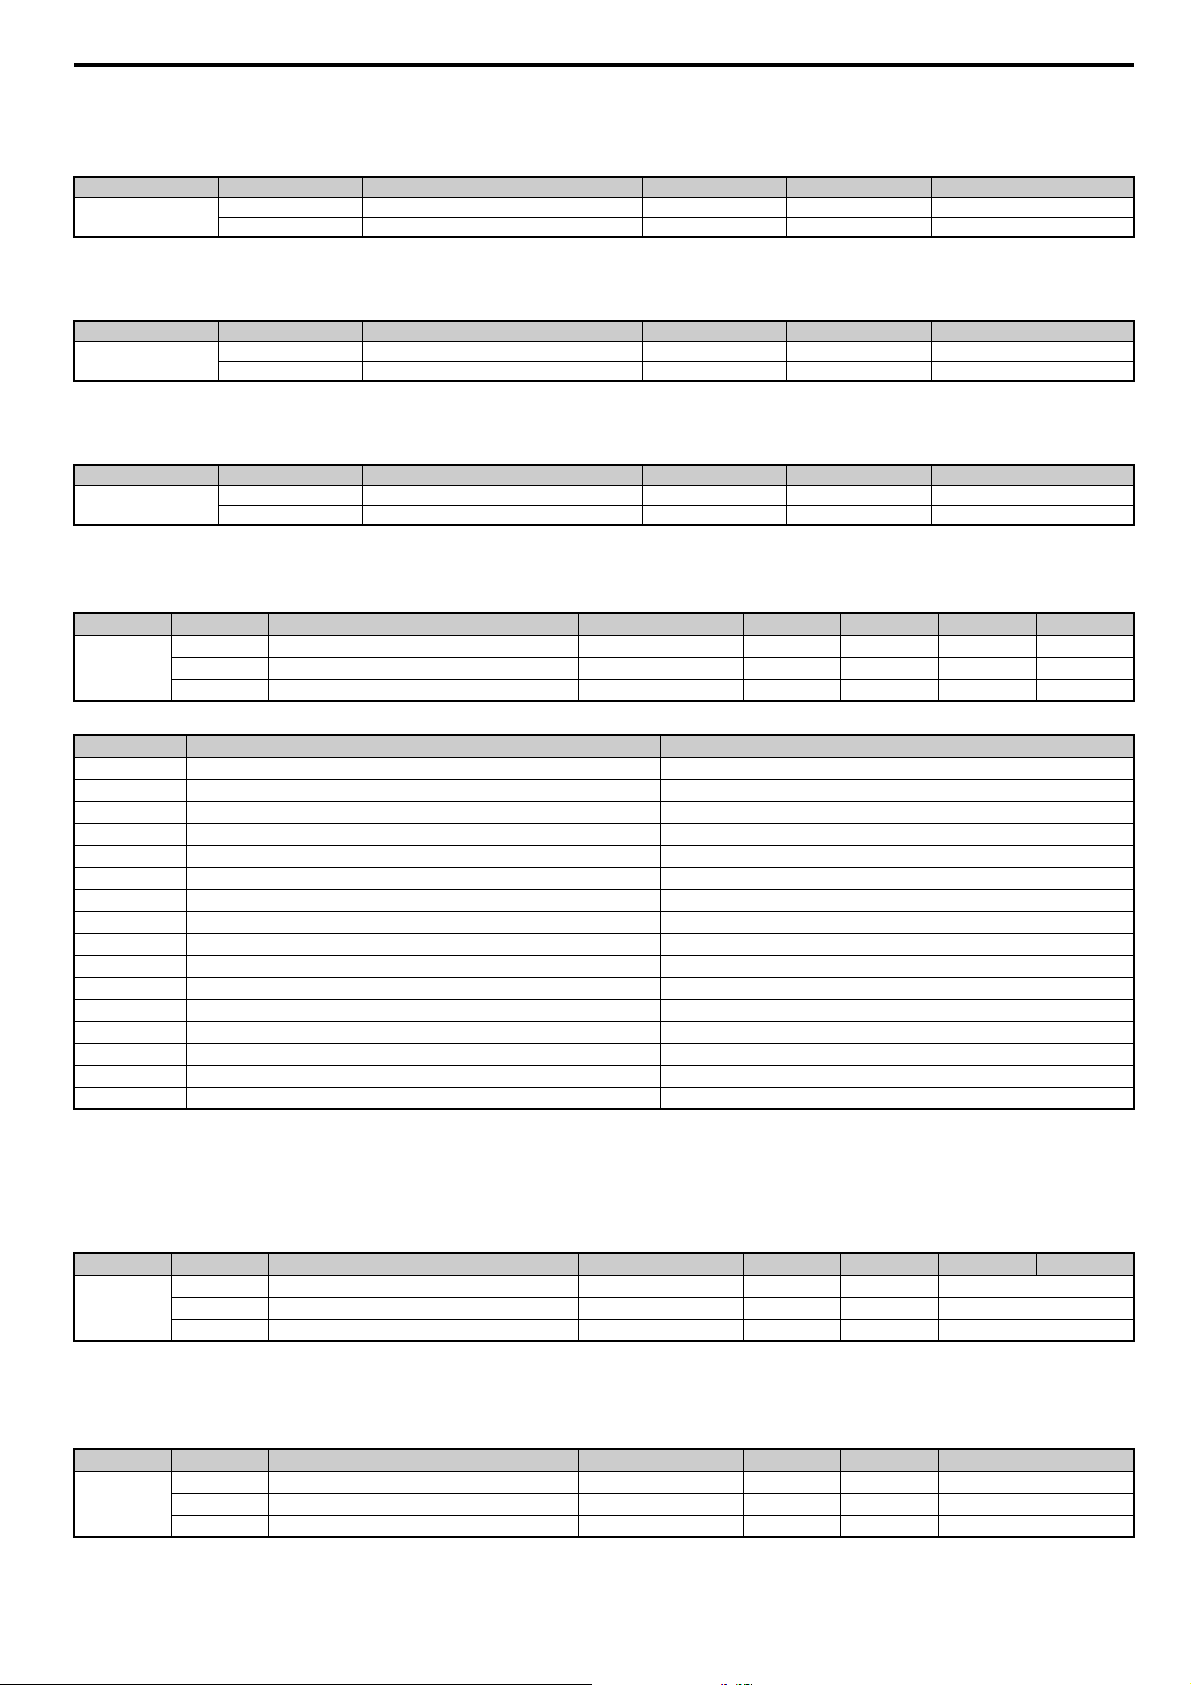
20D0 (Hex) - FM analog output 1
This object controls the FM analog output value.
Index (Hex.) Subindex Content Access PDO Mapping Data Length
20D0
20E0 (Hex) - AM analog output 2
This object controls the AM analog output value.
Index (Hex.) Subindex Content Access PDO Mapping Data Length
20E0
20F0 (Hex) - Multi-function DO output
This object controls the multi-function DO outputs.
Index (Hex.) Subindex Content Access PDO Mapping Data Length
20F0
2100 (Hex)/2101 (Hex) - Drive Status
These objects can be used to monitor the drive status. The value in object 2100 (Hex) is not filtered.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length Update Cycle
0 Number of entries - Read Only Possible 2 byte 2 ms
2100
1 Value - Read Only Tx 2 byte 2 ms
2 MEMOBUS/Modbus register address 00FC (Hex) Read Only No 2 byte -
1 Value Read/Write Rx Tx -
2 MEMOBUS/Modbus register address Read Only No -
1 Value Read/Write Rx Tx -
2 MEMOBUS/Modbus register address Read Only No -
1 Value Read/Write Rx Tx -
2 MEMOBUS/Modbus register address Read Only No -
Bit No. (Hex) Function Description
0 During Run 1: During Run 0: During Stop
1 During Zero Speed 1: During Zero Speed
2 Reverse Running 1: During Reverse Running 0: During Forward Running
3 During Fault Reset Signal Input 1: During Fault Reset Signal Input
4 During Speed Agree 1: During Speed Agree
5 During Drive Ready 1: During Drive Ready 0: Not Ready
6 During Alarm 1: During Alarm
7 During Fault 1: During Fault
8 During Operation Error 1: During Operation Error
9 During Momentary Power Loss 1: During Momentary Power Loss 0: During Power Loss
A NetCtrl Status 1: NetCtrl
B Digital Output 1 Status (function set in drive parameter H2-01) 1: ON 0: OFF
C Digital Output 2 Status (function set in drive parameter H2-02) 1: ON 0: OFF
D Digital Output 3 Status (function set in drive parameter H2-03) 1: ON 0: OFF
E Motor 2 Selected 1: Motor 2 Selected
F Zero-Servo End 1: Zero-Servo End
2110 (Hex) - Output Frequency
This object can be used to monitor the drive output frequency. The unit of the monitor value is determined by drive parameter o1-03 (0 = Hz; 1 = %
with 100% equals parameter E1-04; 2 = rev/min with the motor poles number entered into E2-04/E4/04/E5-04; 3 = user defined parameters o1-10
and 01-11.
The value will be used as the speed reference for speed control (d5-01 = 0) or as the speed limit in torque control (d5-01 = 1).
Index (Hex) Subindex Content Default Access PDO Mapping Data Length Update Cycle
0 Number of entries - Read Only - -
2110
1 Value - Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address 0041 (Hex) Read Only No Unsigned 16
2120 (Hex) - Output Current
This object can be used to monitor the drive output current in units of Ampere. The current value resolution is the same as in drive monitor U1-03
(for details refer to the technical manual of the drive).
Index (Hex) Subindex Content Default Access PDO Mapping Value Range
0 Number of entries - Read Only - -
2120
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 25
1 Value - Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address 00FB (Hex) Read Only No Unsigned 16
Page 26
8 Object Dictionary
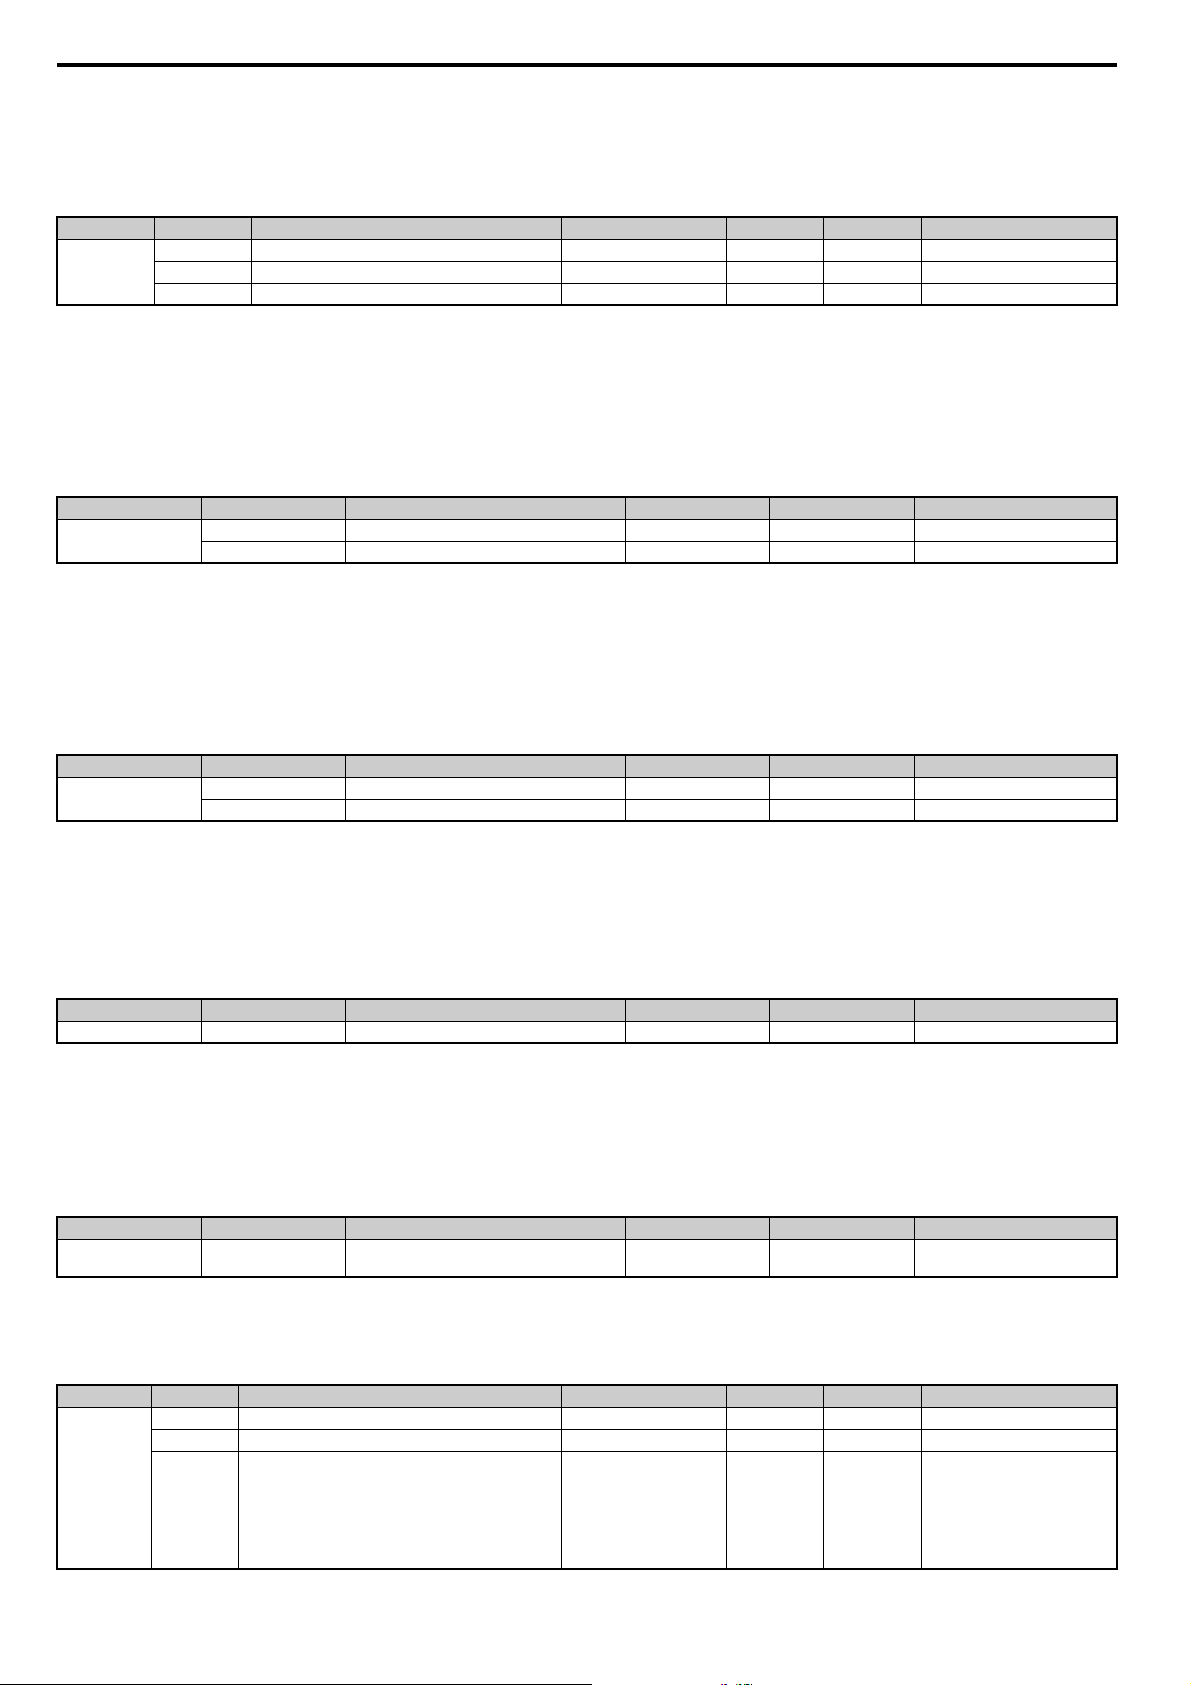
2130 (Hex) - Output Torque Reference
This object can be used to monitor the output torque reference. The availability of this object content depends on the drive control mode. If the
selected control mode does not support this monitor (equal to drive monitor U1-09), the torque reference monitor value will be 0. Refer to the drive
technical manual for details.
Index (Hex) Subindex Content Default Access PDO Mapping Value Range
0 Number of entries - Read Only - -
2130
2140 (Hex) - MEMOBUS/Modbus Read Response
This object contains the data of the drive MEMOBUS/Modbus register specified in object 2040 (Hex). Bytes 1 and 2 of subindex 1 will contain the
data, bytes 3 and 4 will contain the MEMOBUS/Modbus Address read.
0xAAAABBBB ->
0xAAAA = drive register
0xBBBB = Data
Index (Hex) Subindex Content Access PDO Mapping Value Range
2140
2150 (Hex) - MEMOBUS/Modbus Write Response
This object contains the response from the drive when writing a drive parameter using a MEMOBUS/Modbus write command (object 2050 (Hex)).
Bytes 1 and 2 of subindex 1 will contain the data that were written, bytes 3 and 4 will contain the MEMOBUS/Modbus Address that was written to.
0xAAAABBBB ->
0xAAAA = drive register
0xBBBB = Data
1 Value - Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address 0048 (Hex) Read Only No Unsigned 16
0 Number of entries Read Only No Unsigned 8
1 MEMOBUS/Modbus read response Read Only Tx Unsigned 32
Index (Hex) Subindex Content Access PDO Mapping Value Range
2150
0 Number of entries Read Only No Unsigned 8
1 MEMOBUS write response Tx Unsigned 32
2155 (Hex) - PDO Parameter Write Response
Note: Object only available in Powerlink SAFE_OP or OPERATIONAL state. Object data is always cleared when a transition from PRE_OP ' SAFE_
OP is done.
This object contains the response from the drive when writing a drive parameter directly using a RxPDO. Byte 1 and 2 contain the last RxPDO
number that caused the error. Byte 3 contains the number of errors. The error counter is increased when an NOID Online-DRV control data write is
flagged as invalid by the drive (INVSTS2: Bit6, Control command error or local option RxPDO error). This object can only be read if the SI-EL3
option is in Operational state.
Index (Hex) Subindex Content Access PDO Mapping Data Length
2155 0 PDO Parameter Write Response Read Only Tx 3 byte
2160 (Hex) - MEMOBUS/Modbus Not Limited Enter Command Response
This object contains the response from the drive when writing an Enter command using object 2060 (Hex).
Response values:
OK: 0x65766173
ERR: MEMOBUS error code or SDO abort code if SDO request.
Index (Hex) Subindex Content Access PDO Mapping Data Length
2160 -
MEMOBUS/Modbus not limited enter command
response
Read Only Tx 4 byte
2180 (Hex) to 21E0 (Hex) - Configurable Output Objects
Note: This value can only be changed in Powerlink pre-operational state.
The content of these objects can be selected by linking them to drive MEMOBUS/Modbus registers.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
0 Number of entries - Read Only No Unsigned 8
1 Value of mapped drive register - Read Only Tx Unsigned 16
Defaults:
2180 to 21E0
2 MEMOBUS/Modbus register address of content
26 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
0x2180: 0x0049 (Input
Terminal Status)
0x2190: 0x004E (Analog
Input A1 Monitor)
0x21A0-0x21E0: Default:
0xFFFF (No mapping)
Read/Write No Unsigned 16
Page 27
8 Object Dictionary
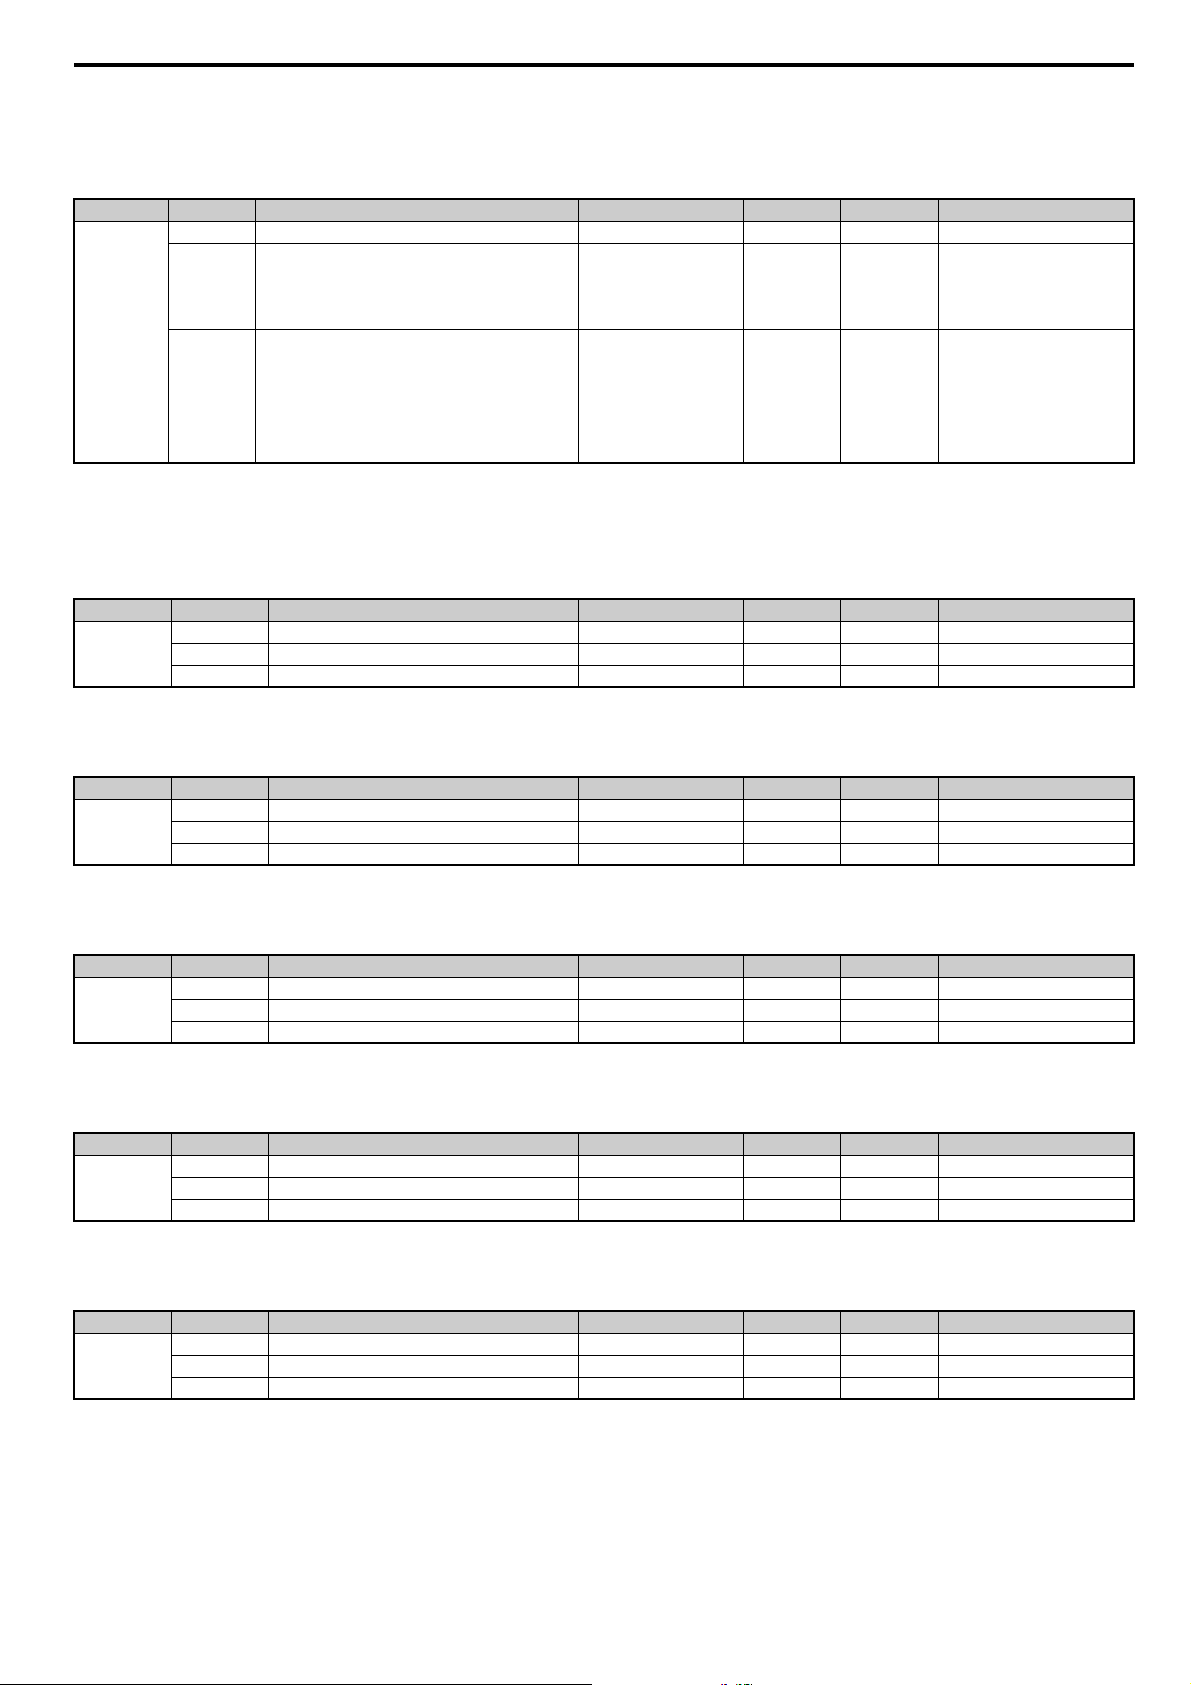
21F0 (Hex) - Configurable Output Object
Note: This value can only be changed in Powerlink pre-operational state.
The content of this object can be selected by linking them to drive MEMOBUS/Modbus registers.
Index (Hex) Subindex Content Content Access PDO Mapping Data Length
0 Number of entries - Read Only No Unsigned 8
Value: 0xAAAABBBB '
1 Value of mapped drive register 1 and 2
21F0
2 MEMOBUS register address of content 1 and 2
AAAA = MEMOBUS
register 1 address
BBBB = MEMOBUS
register 2 address
Value: 0xAAAABBBB '
AAAA = MEMOBUS
register 1 address
BBBB = MEMOBUS
register 2 address
Reg. value=0xFFFF '
Mapping disabled.
Default: 0xFFFFFFFF
2200 (Hex) - Motor Speed
This object can be used to monitor the motor speed. The value in object 2200 (Hex) is not filtered. Setting units are determined by o1-03.
The availability of the object content depends on the drive control mode. If the selected control mode does not support this monitor (equal to drive
monitor U1-05), the object value will be 0. Refer to the drive technical manual for details.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
0 Number of Entries - Read Only No Unsigned 8
2200
1 Motor Speed - Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address of content 0044 (Hex) Read Only No Unsigned 16
Read Only Tx Unsigned 32
Read/Write No Unsigned 32
2210 (Hex) - DC Bus voltage
This object can be used to monitor the DC BUS voltage.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
0 Number of entries - Read Only - -
2210
1 Value 1 V Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address of content 0046 (Hex) Read Only No Unsigned 16
2220 (Hex) - Analog Input Monitor A1
This object can be used to display the analog input A1 level: 100% when input is 10 V.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
0 Number of entries - Read Only - -
2220
1 Value 0.1 % Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address of content 004E (Hex) Read Only No Unsigned 16
2240 (Hex) - Analog Input Monitor A2
This object can be used to display the analog input A2 level: 100% when input is 10 V.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
0 Number of entries - Read Only - -
2240
1 Value 0.1 % Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address of content 004F (Hex) Read Only No Unsigned 16
2260 (Hex) - Analog Input Monitor A3
This object can be used to display the analog input A3 level: 100% when input is 10 V.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
0 Number of entries - Read Only - -
2260
1 Value 0.1 % Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address of content 0050 (Hex) Read Only No Unsigned 16
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 27
Page 28
8 Object Dictionary
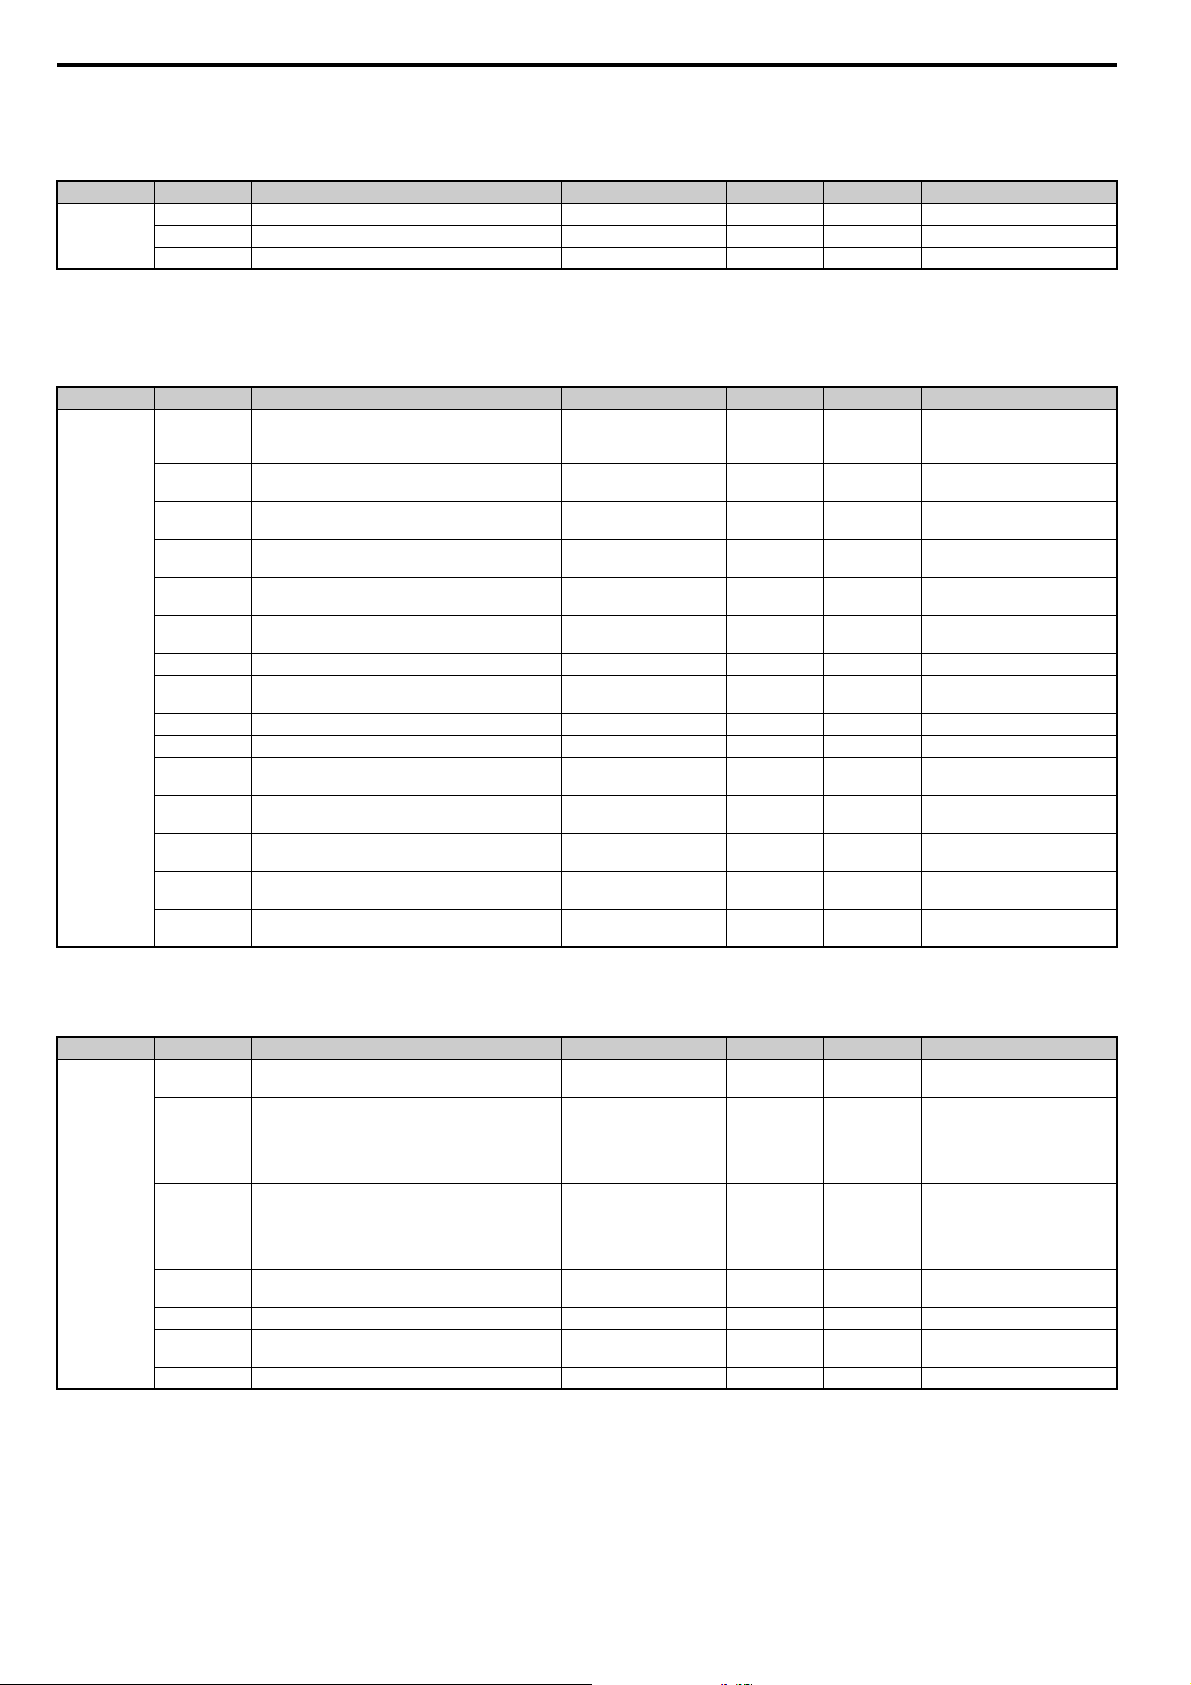
2270 (Hex) - Drive DI Input
This object can be used to display the input terminal status.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
0 Number of entries - Read Only - -
2270
4000 (Hex) - Option NVS FATAL Record
Internal FATAL NVS record for debugging purposes.
Note: Writing 0xFB to sub-index 0 will clear the record in NVS memory.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
4000
1 Value - Read Only Tx Unsigned 16
2 MEMOBUS/Modbus register address of content 0049 (Hex) Read Only No Unsigned 16
Information regarding a system failure/crash is stored
-
1
2
3
4
5
6 NOI System active error bits when event occurred. - Read Only No Unsigned 16
7
8 INV status word when the last error was logged. - Read Only No Unsigned 16
9 Last error logged in object 0x603F. - Read Only No Unsigned 16
10
11
12
13
14
in this object and can be read out for on-site
Total number of FATAL events logged since entry was
Boot firmware revision in flash when the last event
Application firmware revision in flash when the last
Option internal enumerated status code of the logged
Event specific parameter value associated with the
NOI System latched (All errors that have occurred
Event number parameter associated with FATAL
Total running time in milliseconds of option system
since power-up to the FATAL event was triggered.
Internal system Task ID enumeration that causes the
Line in source-code file where the FATAL event was
Name of source-code file where the FATAL event was
troubleshooting.
cleared.
was logged.
event was logged
event.
status event.
since start-up) error bits.
event.
FATAL event.
triggered.
triggered.
- Read/Write No Unsigned 8
- Read Only No Unsigned 32
- Read Only No Unsigned 16
- Read Only No Unsigned 32
- Read Only No Unsigned 16
- Read Only No Unsigned 16
- Read Only No Unsigned 16
- Read Only No Unsigned 32
- Read Only No Unsigned 32
- Read Only No Unsigned 16
- Read Only No Unsigned 16
- Read Only No Visible String
4001 (Hex) - Option Info + Status Record
Provides general information of option system firmware parts and internal system states.
Index (Hex) Subindex Content Default Access PDO Mapping Data Length
Provides general information of option system
firmware parts and internal system states.
Value: 0x00AABBCC
Value: 0x00AABBCC
Boot firmware revision in flash.
AA = Major revision
BB = Minor revision
CC = Build
Application firmware revision in flash.
AA = Major revision
BB = Minor revision
CC = Build
Total running time in milliseconds of option system
NOI System latched (All errors that have occurred
since power-up.
since start-up) error bits.
- Read Only No Unsigned 8
- Read Only No Unsigned 32
- Read Only No Unsigned 32
- Read Only No Unsigned 32
- Read Only No Unsigned 16
4001
0
1
2
3
4 NOI System active error bits. - Read Only No Unsigned 16
5
6 MAC address assigned during manufacturing. - Read Only No Octet string
28 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 29
8 Object Dictionary
Drives and Motion Profile Objects (DSP 402)
The drive supports the Drive and Motion Profile DSP 402 Velocity Mode. Before using the Velocity Mode objects the following parameters have to
be set up in the drive:
• The number of motor poles must be set to E2-04.
• The frequency reference and output frequency display unit must be set to r/min by setting parameter o1-03 = 2.
If these settings are not done properly, the Velocity Mode objects can not be used or the drive might not operate as expected.
Note: Drive and Motion Control (DSP 402) cannot be set or referenced unless o1-03 = 2.
603F (Hex) - Errorcode
This object shows the errorcode in case an error has occurred.
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
603F 0 Errorcode Read Only Tx 0...65535
6040 (Hex) - Controlword
This object sets the device to different states.
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
6040 0 Controlword Read/Write Rx/Tx 0...65535
6041 (Hex) - Statusword
This object shows different states of the device.
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
6041 0 Statusword Read Only Tx 0...65535
6042 (Hex) - vl Target Velocity
This object sets the speed reference. It is internally multiplies with the vl dimension factor (604C). Prior to using the object, drive parameter o1-03
has to be set to min
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e Unit
6042 - vl target velocity Read/Write Rx /Tx -32768...0...32767 r/min
-1
.
6043 (Hex) - vl Velocity Demand
The vl Velocity Demand is the speed reference provided by the ramp function and limiting functions in units of min
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e Unit
6043 - vl velocity demand Read Only Tx -32768...0...32767 r/min
-1
.
6044 (Hex) - vl Velocity Control Effort/Actual Value
-1
The vl Velocity Control Effort is the output frequency of the drive to the motor. The unit is min
. In case of close loop vector control mode the
motor speed can be read out.
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e Unit
6044 - vl control effort Read Only Tx -32768...0...32767 r/min
6046 (Hex) - vl Velocity Min Max Amount
This object provides two subindexes to set the minimum and maximum speed reference in r/min.
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e Unit
vl velocity min amount
vl velocity max amount
Read/Write Rx/Tx
Read/Write Rx/Tx
0...(2
0...(2
32
-1)
32
-1)
r/min
r/min
6046
Minimum speed reference allowed
1
2
d2-02 (Frequency reference lower limit)
Note: The parameter specifies the % rate of E104 maximum output frequency. Internal
parameter calculations needed.
Maximum speed reference allowed
d2-01 (Frequency reference upper limit)
Note: The parameter specifies the % rate of E104 maximum output frequency. Internal
parameter calculations needed.
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 29
Page 30
8 Object Dictionary
6048 (Hex) - vl Velocity Acceleration
The vl velocity acceleration specifies the acceleration time. The quotient of the subindexes delta speed and delta time determines the acceleration
time. The object values correspond to the acceleration time setting in the drive.
Index (Hex) Subindex Content Access PDO Mapping Value Range Unit
6048
1 Acceleration Delta speed Read/Write Rx/Tx
2 Acceleration Delta time Read/Write Rx/Tx 0...65535 sec
0...(2
23
-1)
r/min
6049 (Hex) - vl Velocity Deceleration
The vl velocity min max amount specifies the deceleration time. The quotient of the subindexes delta speed and delta time determines the
deceleration time. The object values correspond to the deceleration time setting in the drive.
Index (Hex) Subindex Content Access PDO Mapping Value Range Unit
6049
1 Deceleration Delta speed Read/Write Rx/Tx
2 Deceleration Delta time Read/Write Rx/Tx 0...65535 sec
0...(2
23
-1)
r/min
604A Hex) - vl Velocity Quick Stop
The vl velocity quick stop specifies the quick stop ramp. The quotient of the subindexes delta speed and delta time determines the quick stop ramp
time. The object values correspond to the fast stop time setting in the drive.
Index (Hex) Subindex Content Access PDO Mapping Value Range Unit
604A
1 Quick Stop Delta speed Read/Write Rx/Tx
2 Quick Stop Delta time Read/Write Rx/Tx 0...65535 sec
0...(2
23
-1)
r/min
604C (Hex) - vl Dimension Factor
The vl dimension factor is multiplied with the target velocity. The quotient of the subindexes vl dimension factor numerator and vl dimension factor
denominator determines the vl dimension factor.
Default Value = 1
This parameter affects other objects such as:
0x6042 vl_target_velocity,
0x6043 vl_velocity_demand.
0x6044 vl_control_effort
0x6046 vl_velocity_min_max_amount.
0x6048 vl_velocity_acceleration
0x6049 vl_velocity_deceleration
0x604A vl_velocity_quick_stop.
and is always used in a product (multiplication).
Index (Hex) Subindex Content Access PDO Mapping Value Range
604C
vl dimension factor numerator
1
2
Internal in Powerlink
memory.
Default Value = 1.
vl dimension factor denominator
Internal in Powerlink
memory.
Default Value = 1.
option card, save in NVS
option card, save in NVS
Read/Write Rx/Tx
Read/Write Rx/Tx
-2
-2
31
...(231-1)
31
...(231-1)
604D (Hex) - vl Pole Number
The vl pole number sets the number of motor poles and is used to calculate all speed related values in r/min. This value corresponds to the number
of motor poles setting in the drive.
E2-04 (Number of motor poles)
Index (Hex) Subindex Content Access PDO Mapping Value Range
604D - vl pole number Read/Write Tx 0...255
6060 (Hex) - Modes of Operation
This object sets the mode of the device.
Value: 2: Velocity mode.
Value: -2: Vendor control mode.
Index (Hex) Subindex Content Access PDO Mapping Value Range
6060 - Modes of Operation Read/Write Rx/Tx -128...127
30 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 31
8 Object Dictionary
6061 (Hex) - Modes of Operation Display
This object shows the mode of the device.
Value: 2: Velocity mode.
Value: -2: Vendor control mode.
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
6061 - Modes of Operation Display Read Only Tx -128...127
60FD (Hex) - Digital Inputs
This object contains the drive digital output status (seen as input to the network).
The content of this object is equal to drive MEMOBUS/Modbus register 004A (Hex) (drive output terminal status monitor U1-11) and depends on
the drive the SI-EL3 option card is used with. For details on the content of this register refer to the technical manual for the drive.
Bit defines:
0-15 = reserved (Set to zero)
16-31 = U1-11 (Output terminal status)
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
60FD 0 Drive digital input status Read Only Tx
Bit No. (Hex) Function Description
0 to F Reserved
10 to 1F Bit 0 to F of drive register 004A (Hex) (drive output terminal status monitor U1-11) 1: ON 0: OFF
60FE (Hex) - Digital Outputs
This object is used to set drive digital inputs (seen as output from the network).
Index (Hex) Subindex Content Access PDO Mapping Va lue Ra ng e
60FE
Bit No. (Hex) Function Description
0 to 17 Reserved (Set to zero)
18 Terminal S3 Function 1=set, 0=clear
19 Terminal S4 Function 1=set, 0=clear
20 Terminal S5 Function 1=set, 0=clear
21 Terminal S6 Function 1=set, 0=clear
22 Terminal S7 Function 1=set, 0=clear
23 Terminal S8 Function 1=set, 0=clear
24 External Fault (EF0) 1=set, 0=clear
25 Fault Reset 1=set, 0=clear
26 to 31 Reserved (Set to zero)
0 Number of elements Read Only - 0...255
1 Physical Outputs Read/Write Rx/Tx
0...(2
0...(2
32
-1)
32
-1)
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 31
Page 32
9 Configuring Manufacturer Specific CANopen Objects
9 Configuring Manufacturer Specific CANopen Objects
This section describes the configuration of manufacturer specific objects that support content selection.
Selectable Object Content
All parameters, monitors and other control registers in the drive are represented by their MEMOBUS/Modbus register. The Powerlink option card
allows the user to select the content of some manufacturer specific objects by mapping them to any of the drives MEMOBUS registers, so that those
objects can be set up to contain the value of drive parameters, monitors as well as other MEMOBUS/Modbus registers (e.g. alarm and fault status,
etc.). Refer to the drive Technical Manual for details on available MEMOBUS/Modbus registers.
Selecting the Object Content
Objects with selectable content have the following structure.
Object Type Subindex
0 Number of entries Read Only No 1 byte
2 Byte
4 Byte
<1> Read/Write access when SI-EL3 is in the Pre-Operational state, Read only access if the SI-EL3 is in the Operational state or if the drive is running.
1 Data depends on object Possible 2 byte
2 MEMOBUS/Modbus register address Read/Write
0 Number of entries Read Only No 1 byte
1 Data depends on object Possible 4 byte
2 MEMOBUS/Modbus register address 1 and 2 Read/Write
Content Access PDO Mapping Data Length
<1> No 2 byte
<1> No 4 byte
To map the content of a certain MEMOBUS/Modbus register of the drive to subindex 1 of an object, the MEMOBUS/Modbus register address must
be written to subindex 2 of the object.
Examples
• In order to map the drive output power monitor (U1-08, 0047 (Hex)) to output object 21A0 (Hex), write 0047 (Hex) to subindex 2 of object 21A0
(Hex).
• In order to map the speed reference 1 (d1-01, 0280 (Hex)) to input object 2090 (Hex), write 0280 (Hex) to subindex 2 of object 2090 (Hex).
• In order to map the input terminal status (U1-10, 0049 (Hex)) and output terminal status (U1-11, 004A (Hex)) to output object 21F0 (Hex) (4
Byte), write 0049 (Hex) to the higher and 004A (Hex) to the lower word of object 2090 (Hex), subindex 2.
Limitations of Object Content Selection
The following limitations have to be considered when setting the content of an object.
• The object content can only be changed when the SI-EL3 option card is in Pre-Operational state and drive is stopped (Run command not active).
• The SI-EL3 can not be switched to the Operational state until the content selection process is complete. Otherwise, an emergency message (code
6301 (Hex)) will be sent.
• When object content selection is ongoing, no other request or command, including Run, should be sent to the drive. Otherwise, an error message
or an emergency message (code 6301 (Hex)) will be sent.
• For 4 byte input objects, MEMOBUS/Modbus register numbers below 0100 (Hex) can be linked in any combination. If MEMOBUS/Modbus
register numbers above 00FF (Hex) are linked to a 4 byte object, the MEMOBUS/Modbus register numbers must be consecutive.
Mapped Register 1 Mapped Register 2
0007 (Hex) 0009 (Hex) Possible
0201 (Hex) 0202 (Hex) Possible
0201 (Hex) 0203 (Hex) Not possible
0200 (Hex) FFFF (Hex) (Disable) Possible
FFFF (Hex) (Disable) 0200 (Hex) Possible
• Register numbers must not be consecutive for 4 Byte output objects.
• A MEMOBUS/Modbus register can no be mapped to two or more objects at the same time.
• MEMOBUS/Modbus registers 0001 (Hex), 0002 (Hex), 0004 (Hex), 0005 (Hex), 0007 (Hex), 0008 (Hex), 0009 (Hex), and 0014 (Hex) are
already linked to not changeable input objects and can not be linked to any object with selectable content. Trying to map one of those registers to
an input object will result in an error message.
32 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 33
10 Process Data Objects (PDO)
10 Process Data Objects (PDO)
PDOs (Process Data Object) will be used for I/O exchange. PDOs are mapped to objects during configuration (PRE-OPERATIONAL state).
TxPDOs are used to transfer data from the option card and RxPDOs are used to transfer data to the option card.
The module supports at least 8 parameters mapped to RxPDO and 8 parameters mapped to TxPDO.
PDOs and Default PDO Setup
The drive supports 15 Receive and 16 Transmit PDOs. The tables below show available PDOs, their default settings and the objects required to set
up when changing the PDO configuration or the PDO mapping.
Transmit PDOs (TxPDO)
The Transmit PDOs have a default mapping according to the table below. The transmit PDOs can be re-mapped by the end user by writing to map
objects 0x1A00-0x1A28, please see Communication Profile Objects (DSP 301) on page 18.
PDO number
1 Sub-index 1: 0x6041#0, 2-bytes (DSP402 status word) 0x1A00
2
6
7
21 Sub-index 1: 0x6042#0, 2-bytes (vl target velocity) 0x1A14
22 Sub-index 1: 0x6043#0, 2-bytes (vl velocity demand) 0x1A15
23
24
25
26
36 Sub-index 1: 0x2100#1, 2-bytes (Drive status) 0x1A23
37 Sub-index 1: 0x2110#1, 2-bytes (Output frequency) 0x1A24
38 Sub-index 1: 0x2120#1, 2-bytes (Output current) 0x1A25
39 Sub-index 1: 0x2130#1, 2-bytes (Output torque reference) 0x1A26
40 Sub-index 1: 0x2140#1, 2-bytes (MEMOBUS/Modbus read response) 0x1A27
41 Sub-index 1: 0x2150#1, 2-bytes (MEMOBUS/Modbus write response) 0x1A28
Sub-index 1: 0x6041#0, 2-bytes (DSP402 status word)
Sub-index 2: 0x6061#0, 2-bytes, (DSP402 Modes of operation display)
Sub-index 1: 0x6041#0, 2-bytes (DSP402 status word)
Sub-index 2: 0x6044#0, 2-bytes, (vl control effort)
Sub-index 1: 0x6041#0, 2-bytes (DSP402 status word)
Sub-index 2: 0x60FD#0, 4-bytes, (Digital inputs)
Sub-index 1: 0x6048#1, 4-bytes (vl Accel delta speed)
Sub-index 2: 0x6048#2, 2-bytes, (vl Accel delta time)
Sub-index 1: 0x6049#1, 4-bytes (vl Decel delta speed)
Sub-index 2: 0x6049#2, 2-bytes, (vl Decel delta time)
Sub-index 1: 0x604A#1, 4-bytes (vl quick-stop delta speed)
Sub-index 2: 0x604A#2, 2-bytes, (vl quick-stop delta time)
Sub-index 1: 0x604C#1, 4-bytes (vl Dimension factor)
Sub-index 2: 0x604C#2, 4-bytes, (vl Dimension factor)
Mapped objects (Hex) Index (Hex)
Transmit PDO Mapping
0x1A01
0x1A05
0x1A06
0x1A16
0x1A17
0x1A18
0x1A19
Receive PDOs (RxPDO)
The Receive PDOs have a default mapping according to the table below. The end user can re-map Receive PDOs by writing to the map objects
0x1600-1628, refer to Communication Profile Objects (DSP 301) on page 18.
PDO number
1 Sub-index 1: 0x6040#0, 2-bytes (DSP402 control word) 0x1600
2
6
7
8
21
22
23
24
36 Sub-index 1: 0x2000#1, 2-bytes (Operation command) 0x1623
37 Sub-index 1: 0x2010#1, 2-bytes (Speed reference/limit) 0x1624
38 Sub-index 1: 0x2020#1, 2-bytes (Torque reference/limit) 0x1625
39 Sub-index 1: 0x2030#1, 2-bytes (Torque compensation) 0x1626
40 Sub-index 1: 0x2040#1, 4-bytes (MEMOBUS/Modbus read request) 0x1627
41 Sub-index 1: 0x2050#1, 4-bytes (MEMOBUS/Modbus write request) 0x1628
Sub-index 1: 0x6040#0, 2-bytes (DSP402 control word)
Sub-index 2: 0x6060#0, 1-bytes, (DSP402 Modes of operation)
Sub-index 1: 0x6040#0, 2-bytes (DSP402 control word)
Sub-index 2: 0x6042#0, 2-bytes, (vl target velocity)
Sub-index 1: 0x6040#0, 2-bytes (DSP402 control word)
Sub-index 2: 0x60FE#1, 4-bytes, (Physical digital outputs)
Sub-index 1: 0x6040#0, 2-bytes (DSP402 control word)
Sub-index 2: 0x6060#0, 1-bytes, (DSP402 Modes of operation)
Sub-index 1: 0x6048#1, 4-bytes (vl Accel delta speed)
Sub-index 2: 0x6048#2, 2-bytes, (vl Accel delta time)
Sub-index 1: 0x6049#1, 4-bytes (vl Decel delta speed)
Sub-index 2: 0x6049#2, 2-bytes, (vl Decel delta time)
Sub-index 1: 0x604A#1, 4-bytes (vl quick-stop delta speed)
Sub-index 2: 0x604A#2, 2-bytes, (vl quick-stop delta time)
Sub-index 1: 0x604C#1, 4-bytes (vl Dimension factor)
Sub-index 2: 0x604C#2, 4-bytes, (vl Dimension factor)
Mapped objects (Hex) Index (Hex)
Receive PDO Mapping
0x1601
0x1605
0x1606
0x1607
0x1614
0x1615
0x1616
0x1617
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 33
Page 34
10 Process Data Objects (PDO)
RxPDO Mapped Drive Registers Above 0x0100 Range
Drive registers above 0x0100 cannot be configured as process data exchanged on each interface scan cycle. To be able to RxPDO map those objects
on Powerlink the drive registers above 0x0100 are refreshed every 8 ms, the drive registers below 0x0100 are refreshed every 1 ms. The drive
registers above 0x0100 are using the overlaid MEMOBUS/Modbus channel in interface to write the drive registers required.
ENTER command management for drive registers above 0x0100 control sets:
• New value only written against drive if it changes from the previously written value.
• If a value update is detected the write will be scheduled directly after the RxPDO Powerlink
• If the written value via MEMOBUS/Modbus failed for some reason, i.e. Parameter cannot be written when the drive is running, a new retry will
be triggered after 8 ms.
• If a RAM ENTER command is required for the written value to be used by the drive, the ENTER command will be written when the last register
that should be updated in an slow IO data scan set update is triggered.
• E.g. mapped drive registers: A: 0x0200, B: 0x0201, C: 0x0203
• All three registers change at the same time:
RAM ENTER command executed with C.
• Only register 0x0200 changes
RAM ENTER command executed with A.
process data cycle is complete.
34 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 35
11 Drive Parameter, Monitor and Control Register Access
11 Drive Parameter, Monitor and Control Register Access
All drive parameters, monitors, and other control registers are represented by their MEMOBUS/Modbus register. The registers can be read or
written by accessing these registers through the SI-EL3 option card.
MEMOBUS/Modbus registers can be directly read or written using MEMOBUS/Modbus read/write commands. The registers can also be mapped
to the content of a manufacturer specific object and then be accessed by reading from or writing to this object. Refer to Selecting the Object Content
on page 32 for details on object content selection.
When writing drive parameters, certain precautions concerning message timing must be taken into account.
• The drive requires a certain time to activate changes to parameter values. When changing multiple parameters, make sure to add a wait time
between write requests.
• If an Enter command is issued, make sure to add a wait time between the Enter command and the next message.
Refer to the drive technical manual for information about MEMOBUS/Modbus addresses available in the drive and the wait times required between
parameter write requests and Enter commands.
Drive Parameter and Monitor Access by MEMOBUS/Modbus Read/Write Commands
Reading a Drive Register, Parameter or Monitor
Reading a drive parameter, monitor or control register using a MEMOBUS/Modbus read command requires the following steps:
• Write the address of the drive MEMOBUS/Modbus register to be read to subindex 0 of object 2040 (Hex).
• Read the value of the drive MEMOBUS/Modbus register from the MEMOBUS/Modbus read response in subindex 1 of object 2140 (Hex).
Objects 2040 (Hex) and 2140 (Hex) can both be mapped to PDOs.
Writing a Parameter or Drive Control Register
Writing to drive parameters or control registers can be performed following the steps below:
• Write the value and the MEMOBUS/Modbus address of the drive parameter or control register to subindex 1 of object 2050 (Hex).
• Read the MEMOBUS/Modbus write response from subindex 1 of object 2150 (Hex) in order to verify that the item is written correctly.
If drive parameters are written and parameter H5-11 in the drive is set to 0, additionally a RAM Enter command (object 2060 (hex)) must be issued
in order let the change take effect. To store the parameter change in the non-volatile memory of the drive, a ROM Enter command (object 2070
(hex)) must be issued instead. An Enter command can be issued by performing the steps below.
• Write “save” (73H + 61H + 76H + 65H) to subindex 1 of object 2060 (Hex) for a RAM Enter command, or to subindex 1 of object 2070 (Hex) for
a ROM Enter command.
• When using a RAM Enter command, read the Enter command response from object 2160 (hex) in order to verify the Enter command is
performed successfully.
Note: When multiple drive parameters are changed, only one Enter command is required after the last parameter value to activate all parameter changes.
Objects 2050/01 (Hex), 2060 (Hex), 2070 (Hex), 2150/01 (Hex) and 2160 (Hex) can be mapped to PDOs.
Initializing the Drive
The drive can be initialized by writing the corresponding initialization code to Modbus/MEMOBUS register 0103 (object 1011 hex) (drive
parameter A1-03; refer to the technical manual of the drive for details on initialization codes). The initialization is performed only if drive parameter
H5-11 is set to “0” and if an Unlimited Enter Command is sent after setting register 0103 (object 1011 hex).
In order to initialize a drive via Powerlink communications follow the instructions below:
1. Read out the value of drive parameter H5-11 using a Modbus/MEMOBUS Read Request (Obj. 2040 (hex)) on drive register 04C3 (hex) (H5-11).
2. If the content of register 04C3 (hex) is “1” then change it to “0” using a Modbus/MEMEOBUS Write Request (Obj. 2050 (hex)).
3. Set drive parameter A1-03 to the desired initialization mode. For example, in order to perform a “2-Wire Initialization”, write “08AC” (hex) (2220) to
Modbus/MEMOBUS register 0103 (object 1011 hex).
4. Finish the initialization by sending an Unlimited Enter Command (Obj. 2070 (Hex)).
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 35
Page 36
12 Fault Diagnosis and Possible Solutions
12 Fault Diagnosis and Possible Solutions
Powerlink Option Card Error Codes
The following error codes will be shown in object 1003, subindex 01 if the correspondent error occurred on the drive.
Inverter and Powerlink
Emergency Object (EMCY)
The emergency object is used for sending fault information from the communication module to the CANopen/Powerlink
The emergency object is triggered by a fault event from the host or the option card itself. An emergency object is transmitted only once per 'error
event'.
Emergency error codes are specified for a number of events. Emergency word specification:
Byte 0 1 2 3 4 5 6 7
Content
Emergency error
code
Emergency Messages, DSP301 & DSP402
The error codes specified in the list below can be read from CANopen object 0x1003 (Pre-defined error field)
Error Code (Hex) Meaning Drive Display INVR:0x0080 Enum Value
0000 No error No error 0x00
3220 DC bus undervoltage Uv1 0x02
5200 Control power supply undervoltage Uv2 0x03
3221 DC bus charging circuit fault Uv3 0x04
2330 Ground fault GF 0x06
2220 Over current oC 0x07
3210 DC bus overvoltage ov 0x08
4280 Heatsink overheat oH 0x09
4210 Heatsink overheat oH1 0x0A
2310 Motor overload oL1 0x0B
2221 Drive overload oL2 0x0C
2311 Overtorque detection 1 oL3 0x0D
2312 Overtorque detection 2 oL4 0x0E
5420 Braking transistor fault rr 0x0F
4410 Internal braking resistor overheat rH 0x10
5441 External fault 3 EF3 0x11
5442 External fault 4 EF4 0x12
5443 External fault 5 EF5 0x13
5444 External fault 6 EF6 0x14
5445 External fault 7
5446 External fault 8
FF17 Cooling FAN fault FAn 0x17
7180 Motor over speed (control mode using PG) oS 0x18
8321 Speed deviation (control mode using PG) dEv 0x19
7305 PG fault (control mode using PG) PGo 0x1A
3130 Input phase loss PF 0x1B
3300 Output phase loss LF 0x1C
FF01 Motor overheat alarm oH3 0x1D
5300 Digital operator disconnected oPr 0x1E
5530 EEPROM error Err 0x1F
FF08 MEMOBUS/Modbus Error CE 0x21
FF07 BUS error bUS 0x22
FF06 Control fault CF 0x25
5481 Fault input from option card EF0 0x27
FF02 PID feedback lost FbL 0x28
FF03 Undertorque detected 1 UL3 0x29
FF04 Undertorque detected 2 UL4 0x2A
FF05 High slip braking OL oL7 0x2B
FF31 Intermediary voltage fault VCF 0x31
FF36 Output current imbalance LF2 0x36
FF3B Too many speed search restarts SEr 0x3B
FF41 PID feedback loss FbH 0x41
FF0D External fault at input terminal S1 EF1 0x42
Faults
Error register object
0x1001
Table 14 Emergency Word Specification
Manufacturer specific error info. Not used. Set to zero.
Table 15 Error Codes
EF7 0x17
EF8 0x16
network.
36 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 37
12 Fault Diagnosis and Possible Solutions
Error Code (Hex) Meaning Drive Display INVR:0x0080 Enum Value
FF0E External fault at input terminal S2 EF2 0x43
FF44 Mechanical weakening detection 1 oL5 0x44
FF45 Mechanical weakening detection 2 UL5 0x45
FF46 Current offset fault CoF 0x46
FF47 Programming Error 1 PE1 0x47
FF49 Current offset fault dWFL 0x49
6301 Error during object content selection - -
SDO Abort Codes
SDO abort codes are supported as specified in DS301. Additionally the abort codes listed below are implemented.
Table 16 SDO Abort Codes
SDO Abort Code Description
Consecutive MEMOBUS/Modbus Read/Write/Enter commands are sent but the wait time between messages is too short.
0602 0010 (Hex)
0602 0022 (Hex)
A MEMOBUS/Modbus Read or Write Response (2140 (Hex) and 2150 (Hex)) was attempted but no or an incorrect
MEMOBUS/Modbus address has been written to object 2040 (Hex) or 2050 (Hex) before.
A MEMOBUS/Modbus write request has been sent during DC bus under voltage.
Drive Profile DSP402 is used and a value is written to object 6042 (Hex) (vl Target Velocity) while the drive status is not
“Operation Enable”.
Object 2155 (Hex) is tried to be read while the SI-EL3 option is not in “Operational” state.
A MEMOBUS/Modbus Read or Write command (2040 (Hex) and 2050 (Hex)) was performed with an invalid MEMOBUS/
Modbus address.
Drive-Side Error Codes
Drive-side error codes appear on the drive’s digital operator. Causes of the errors and corrective actions are listed in Table 17 and Table 8. For
additional error codes, refer to the technical manual for the drive.
The bUS (Powerlink
they occur as an alarm, the “ALM” LED on the drive digital operator will blink and the alarm code will flash in the display. When these occur as a
fault, the “ALM” LED will light and the display will show the fault code.
If communication stops while the drive is running, check the following items:
•Is the Powerlink
• Is the communication line properly connected to the Powerlink Option? Is it loose?
• Is the controller program working? Has the controller CPU stopped?
• Did a momentary power loss interrupt communications?
Faults
Ta bl e 17 lists possible faults when using a communication option. The drive’s fault contact will close if one of these faults occur.
Master controller (PLC) has stopped communicating.
Communication cable is not connected properly.
A data error occurred due to noise.
Powerlink
Option is damaged. If there are no problems with the wiring and the error continues to occur, replace the Powerlink Option.
A Powerlink state transition from OPPRE_OP_1 was made
when the drive was in OPERATION enabled.
Option Communication Error) and EF0 (External Fault Input from the Powerlink Option) may appear as an alarm or a fault. If
Option properly installed?
Table 17 Fault Display and Possible Solutions
Digital Operator Display Fault Name
bUS
Cause Possible Solution
Powerlink
After establishing initial communication, the connection was lost.
Only detected when the run command or frequency reference is assigned to the option (b1-01=3 or b1-02=3).
Check for faulty wiring.
Correct any wiring problems.
Check the various options available to minimize the effects of noise.
Take steps to counteract noise in the control circuit wiring, main circuit lines, and ground wiring.
If a magnetic contactor is identified as a source of noise, install a surge absorber to the contactor coil.
Make sure the cable used fulfills the Powerlink
Option side.
Check and correct state machine transitions in control word.
Option Communication Error
requirements. Ground the shield on the controller side and on the Powerlink
Digital Operator Display Fault Name
EF0
Cause Possible Solution
An external fault is being sent from the upper controller (PLC).
Problem with the upper controller (PLC) program. Check the program used by the upper controller (PLC) and make the appropriate corrections.
External Fault Input from Powerlink Option
The alarm function for an external device has been triggered.
Remove the cause of the external fault.
Reset the external fault input from the upper controller (PLC) device.
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 37
Page 38
12 Fault Diagnosis and Possible Solutions
Digital Operator Display Fault Name
oFA00
Cause Possible Solution
Non-compatible option connected to the drive.
Digital Operator Display Fault Name
oFA01
Cause Possible Solution
Problem with the connectors between the drive and Powerlink
Option.
Digital Operator Display Fault Name
to
oFA30 and oFA32
Cause Possible Solution
Drive system is overloaded.
Drive is not properly processing the state.
Powerlink Option Card Fault
The drive does not support the option board plugged in.
1. Check drive firmware version as described on page 12.
2. If drive firmware version is correct, replace option card.
3. Replace the drive.
Powerlink Option Card Fault
Option card is not properly connected.
Turn the power off and check the connectors between the drive and Powerlink
Option card has detected a Communication Option card ID error
Option card has detected a Sum check error
Force Powerlink state change to NOT_ACTIVE/BASIC_ETHERNET
Option.
Digital Operator Display Fault Name
to
oFA30 to oFA43
Cause Possible Solution
Option card hardware fault
Digital Operator Display Fault Name
oFb00
Cause Possible Solution
The Powerlink
option card has been plugged into option port
CN5-B.
Digital Operator Display Fault Name
oFb02
Cause Possible Solution
Two or more input option cards (analog, digital or
communication) have been connected to the drive at the same
time.
Digital Operator Display Fault Name
oFc00
Cause Possible Solution
The Powerlink
CN5-C.
option card has been plugged into option port
Powerlink Option Card Fault
Communication ID error
Replace the Powerlink
Option. Contact YASKAWA for assistance.
Option Card Fault at Connector CN5-B
Non-compatible option card is connected.
Always use option port CN5-A for communication option cards.
Option Card Fault at Connector CN5-B
Two of the same option cards are connected at the same time.
Use either an analog input option AI-A3 or a digital input option DI-A3 or a communication option card. Never use two of
these cards at the same time.
Option Card Fault at Connector CN5-C
Non-compatible option card is connected.
Drive is not processing the internal interface protocol. Drive does not support Powerlink option card
Always use option port CN5-A for communication option cards.
Digital Operator Display Fault Name
oFc02
Option Card Fault at Connector CN5-C
Two of the same option cards are connected at the same time.
Cause Possible Solution
Two or more input option cards (analog, digital or
communication) have been connected to the drive at the same
time.
Use either an analog input option AI-A3 or a digital input option DI-A3 or a communication option card. Never use two of
these cards at the same time.
38 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 39
12 Fault Diagnosis and Possible Solutions
Minor Faults and Alarms
Table 6 lists up alarms that might occur during operation using a communication option board. If a multi function digital output of the drive is
programmed for H2- = 10, the output will close if these alarms occur.
Digital Operator Display Minor Fault Name
CALL
Cause Possible Solution
Communication wiring is faulty, there is a short circuit, or
something is not connected properly.
Programming error on the master side Check communications at start-up and correct programming errors.
Communication circuitry is damaged. Replace the drive if the fault continues to occur.
Digital Operator Display Minor Fault Name
EEP
Cause Possible Solution
Communication wiring is faulty, there is a short circuit, or
something is not connected properly.
EEPROM checksum error
Serial Communication Transmission Error
Communication has not yet been established.
Check for wiring errors.
Correct the wiring.
Remove and ground shorts and reconnect loose wires.
EEPROM Error
EEPROM checksum error
Check for wiring errors.
Correct the wiring.
Remove and ground shorts and reconnect loose wires.
If these errors occur, the object dictionary will be reset to its default values.
After the object dictionary has been changed and object dictionary contents are then changed, execute a Store Parameter
command (Index = 1010 (Hex)).
If the object dictionary has not been changed, execute a Restore Parameter command (Index = 1011 (Hex)).
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 39
Page 40
13 Specifications
MANUAL NO.ޓYEU SIEP C710616 86A
Published in Germany
September 2013
13-9
Date of
publication
Date of original
publication
13 Specifications
Specifications
Table 18 Option Card Specifications
Items Specifications
Model SI-EL3
Communication Profile
Connector RJ45 connector
Communications Speed 10/100 Mbps
Ambient Temperature –10 C to +50 C
Humidity up to 95% RH (no condensation)
Storage Temperature –20 C to +60 C (allowed for short-term transport of the product)
Area of Use Indoor (free of corrosive gas, airborne particles, etc.)
Internal Scan Cycle
A1000: 1 ms
Revision History
The revision dates and the numbers of the revised manuals appear on the bottom of the back cover.
DS 301 Ver. 4.02
DSP 402 Ver. 3.0 Velocity Mode
Date of Publication Revision Number Section Revised Content
September 2013 First Edition
40 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
Page 41
13 Specifications
YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual 41
Page 42
13 Specifications
DRIVE CENTER (INVERTER PLANT)
2-13-1, Nishimiyaichi, Yukuhashi, Fukuoka, 824-8511, Japan
Phone: 81-930-25-3844 Fax: 81-930-25-4369
http://www.yaskawa.co.jp
YASKAWA ELECTRIC CORPORATION
New Pier Takeshiba South Tower, 1-16-1, Kaigan, Minatoku, Tokyo, 105-6891, Japan
Phone: 81-3-5402-4502 Fax: 81-3-5402-4580
http://www.yaskawa.co.jp
YASKAWA AMERICA, INC.
2121 Norman Drive South, Waukegan, IL 60085, U.S.A.
Phone: (800) YASKAWA (927-5292) or 1-847-887-7000 Fax: 1-847-887-7310
http://www.yaskawa.com
YASKAWA ELÉTRICO DO BRASIL LTDA.
Avenda Fagundes Filho, 620 Bairro Saude, São Paulo, SP04304-000, Brasil
Phone: 55-11-3585-1100
Fax: 55-11-5581-8795
http://www.yaskawa.com.br
YASKAWA EUROPE GmbH
Hauptstrasse 185, 65760 Eschborn, Germany
Phone: 49-6196-569-300 Fax: 49-6196-569-398
http://www.yaskawa.eu.com
YASKAWA ELECTRIC UK LTD.
1 Hunt Hill Orchardton Woods, Cumbernauld, G68 9LF, United Kingdom
Phone: 44-1236-735000
Fax: 44-1236-458182
http://www.yaskawa.co.uk
YASKAWA ELECTRIC KOREA CORPORATION
7F, Doore Bldg. 24, Yeoido-dong, Yeoungdungpo-gu, Seoul, 150-877, Korea
Phone: 82-2-784-7844
Fax: 82-2-784-8495
http://www.yaskawa.co.kr
YASKAWA ELECTRIC (SINGAPORE) PTE. LTD.
151 Lorong Chuan, #04-01, New Tech Park, 556741, Singapore
Phone: 65-6282-3003
Fax: 65-6289-3003
http://www.yaskawa.com.sg
YASKAWA ELECTRIC (SHANGHAI) CO., LTD.
No. 18 Xizang Zhong Road, 17F, Harbour Ring Plaza, Shanghai, 200001, China
Phone: 86-21-5385-2200
Fax: 86-21-5385-3299
http://www.yaskawa.com.cn
YASKAWA ELECTRIC (SHANGHAI) CO., LTD. BEIJING OFFICE
Room 1011, Tower W3 Oriental Plaza, No. 1 East Chang An Ave.,
Dong Cheng District, Beijing, 100738, China
Phone: 86-10-8518-4086
Fax: 86-10-8518-4082
YASKAWA ELECTRIC TAIWAN CORPORATION
9F, 16, Nanking E. Rd., Sec. 3, Taipei, 104, Taiwan
Phone: 886-2-2502-5003
Fax: 886-2-2505-1280
In the event that the end user of this product is to be the military and said product is to be employed in any weapons systems or the manufacture
thereof, the export will fall under the relevant regulations as stipulated in the Foreign Exchange and Foreign Trade Regulations. There
fore, be sure
to follow all procedures and submit all relevant documentation according to any and all rules, regulations and laws that may apply.
Specifications are subject to change without notice for ongoing product modifications and improvements.
©
2013 YASKAWA EUROPE GMBH. All rights reserved.
Published in Germany
September 2013
13-9
MANUAL NO. YEU SIEP C710616 86A
Technical Manual
YASKAWA AC Drive A1000 Option
YASKAWA EUROPE GMBH
42 YASKAWA EUROPE GMBH YEU SIEP C710616 86A - AC Drive A1000 Option Powerlink - Technical Manual
 Loading...