

Page 1
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany
Phone +49 721 4846
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
H-811.D2 and H-811.S2
Hexapod Microrobots
Contents
Introduction 2
Precision-Class 6-Axis Positioning System ........................................................................................................... 2
Model Overview .................................................................................................................................................. 2
Recommended Controller (to be ordered separately) ........................................................................................ 2
Other Applicable Documents 3
Scope of Delivery 4
Connecting the Hexapod to the C-887.5xx Controller 4
Dimensions 6
Technical Data 8
Data Table ............................................................................................................................................................ 8
Maximum Ratings ................................................................................................................................................ 9
Ambient Conditions and Classifications .............................................................................................................. 9
Pin Assignment 10
Power Supply ..................................................................................................................................................... 10
Data Transmission ............................................................................................................................................. 10
CIPA Certificate 12
Page 2
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 2 / 12
Phone +49 721 4846
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
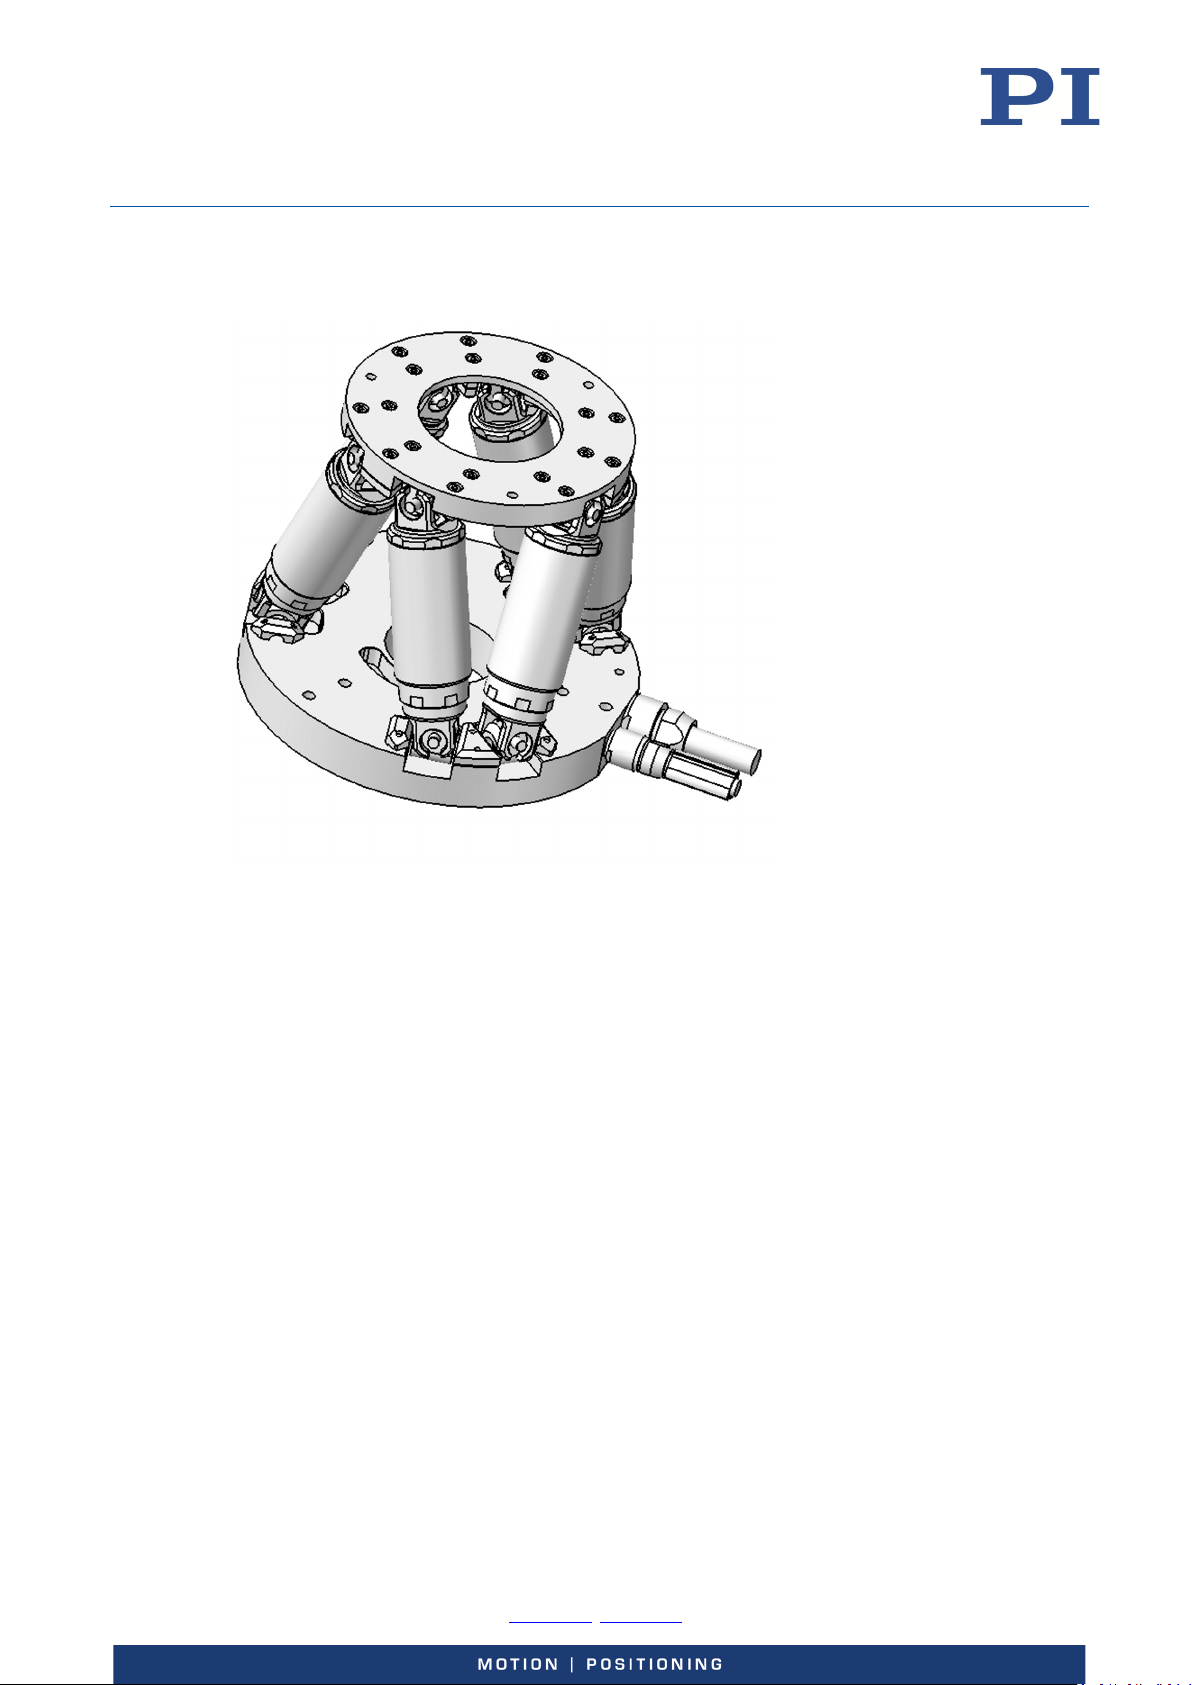
Introduction
Precision-Class 6-Axis Positioning System
Parallel-kinematic design for six degrees of freedom making it significantly more compact and stiff than serial-kinematic
systems, higher dynamic range, no moved cables: Higher reliability, reduced friction
Model Overview
H-811.D2 Miniature Hexapod Microrobot, Direct Drive, 10 mm/s, 5 kg Load, 2 m Cable, HD Sub-D Connector
H-811.S2 Miniature Hexapod Microrobot, Direct Drive, 20 mm/s, 5 kg Load, 2 m Cable, HD Sub-D Connector
Recommended Controller (to be ordered separately)
C-887.5xx 6D Hexapod Controller, TCP/IP, RS-232, Bench-Top Device, Control of Two Additional Servo-Motor Axes
Included; various models available
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 3
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 3 / 12
Phone +49 721 4846
− Overview for troubleshooting
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
Other Applicable Documents
Description Document
H-811 Hexapod
Microrobot
C-887.5xx
Hexapod
Controller
C-887 Wave
Generator
Functions
MS199E user manual for H-811.D1 Hexapod models.
This manual is also valid for H-811.D2 and H-811.S2 Hexapod models, except for the
information superseded by the H811T0019 Technical Note (this document).
Refer to the MS199E user manual for the following information:
− Safety instructions and product description
− Instructions for unpacking, installation, start-up, and maintenance of the
Hexapod
MS204E user manual
Technical Notes for the individual controller models
Documentation for the PC software that comes with the Hexapod controller
C887T0013 Technical Note, included in the controller CD C-887.CD (relevant for
corresponding operation of H-811.S2; e.g. shaker applications)
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 4
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 4 / 12
Phone +49 721 4846
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
Scope of Delivery
Order Number Items
H-811 Hexapod according to your order, cable permanently installed
000015165 Steward snap-on ferrite suppressor
Packaging, consisting of:
Outer box
Inner box
Two pads for sliding onto the inner box
Internal cushion, bottom
Internal cushion, cover
Pallet
Documentation, consisting of:
H811T0019 Technical Note for H-811.D2 and H-811.S2 Hexapod models (this document)
H811T0001 Technical Note on unpacking the Hexapod
MS199E User manual for the Hexapod
Screw sets:
000020110 Mounting accessories:
6 M4x25 hex-head cap screws ISO 4762
1 Allen wrench 3.0 DIN 911
000036450 Accessories for connection to the grounding system:
1 flat-head screw with cross recess M4x8 ISO 7045
2 washers, form A-4.3 DIN 7090
2 safety washers, Schnorr Ø 4 mm N0110
Connecting the Hexapod to the C-887.5xx Controller
1. Read and observe the following installation instructions:
• Instructions in the user manual of the Hexapod, especially sections „General Notes on
Installation“, „Determining the Permissible Load and Working Space“, „Attaching the Snap-On
Ferrite Suppressor“, „Grounding the Hexapod“, „Mounting the Hexapod on a Surface“ and
„Affixing the Load to the Hexapod“.
• Instructions in the user manual of the Hexapod controller, especially sections „General Notes on
Installation“ and „Determining the Working Space and Permissible Load of the Hexapod“.
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 5
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 5 / 12
Phone +49 721 4846
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
2. Make sure that the Hexapod controller is switched off (see user manual of the Hexapod controller).
3. Connect the H-811 Hexapod to the Hexapod controller:
a) Connect the HD Sub-D 78 (m) connector of the data transmission cable to the Hexapod socket
of the controller.
b) Connect the M12 connector of the power supply cable to the 24 V Out 7 A socket of the
controller.
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 6
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 6 / 12
Phone +49 721 4846
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
Dimensions
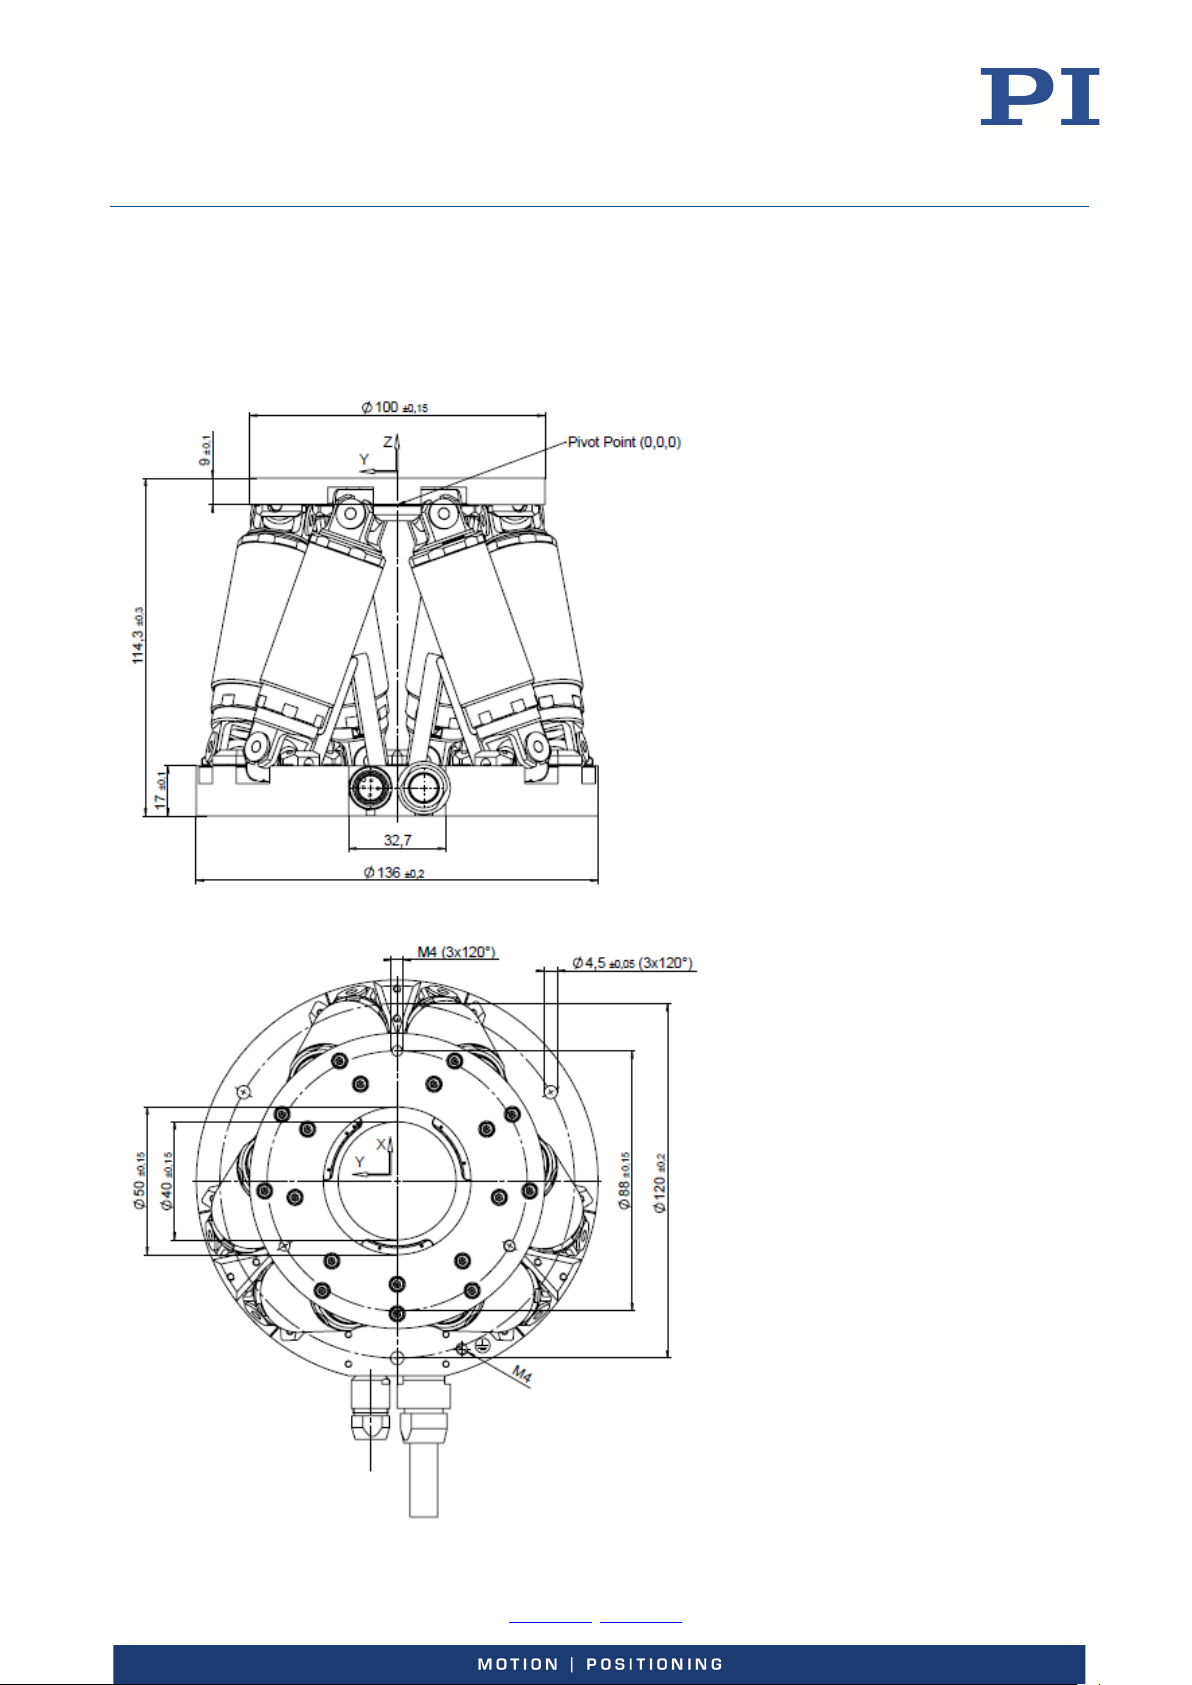
All figures show the Hexapod in the reference position. Dimensions in mm. Note that the decimal places are
separated by a comma in the drawings.
The (0,0,0) coordinates refer to the origin
of the XYZ coordinate system. When the
default settings of the Hexapod controller
are used and the Hexapod is in the
reference position, the pivot point is
located at the origin of the XYZ
coordinate system.
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 7
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 7 / 12
Phone +49 721 4846
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
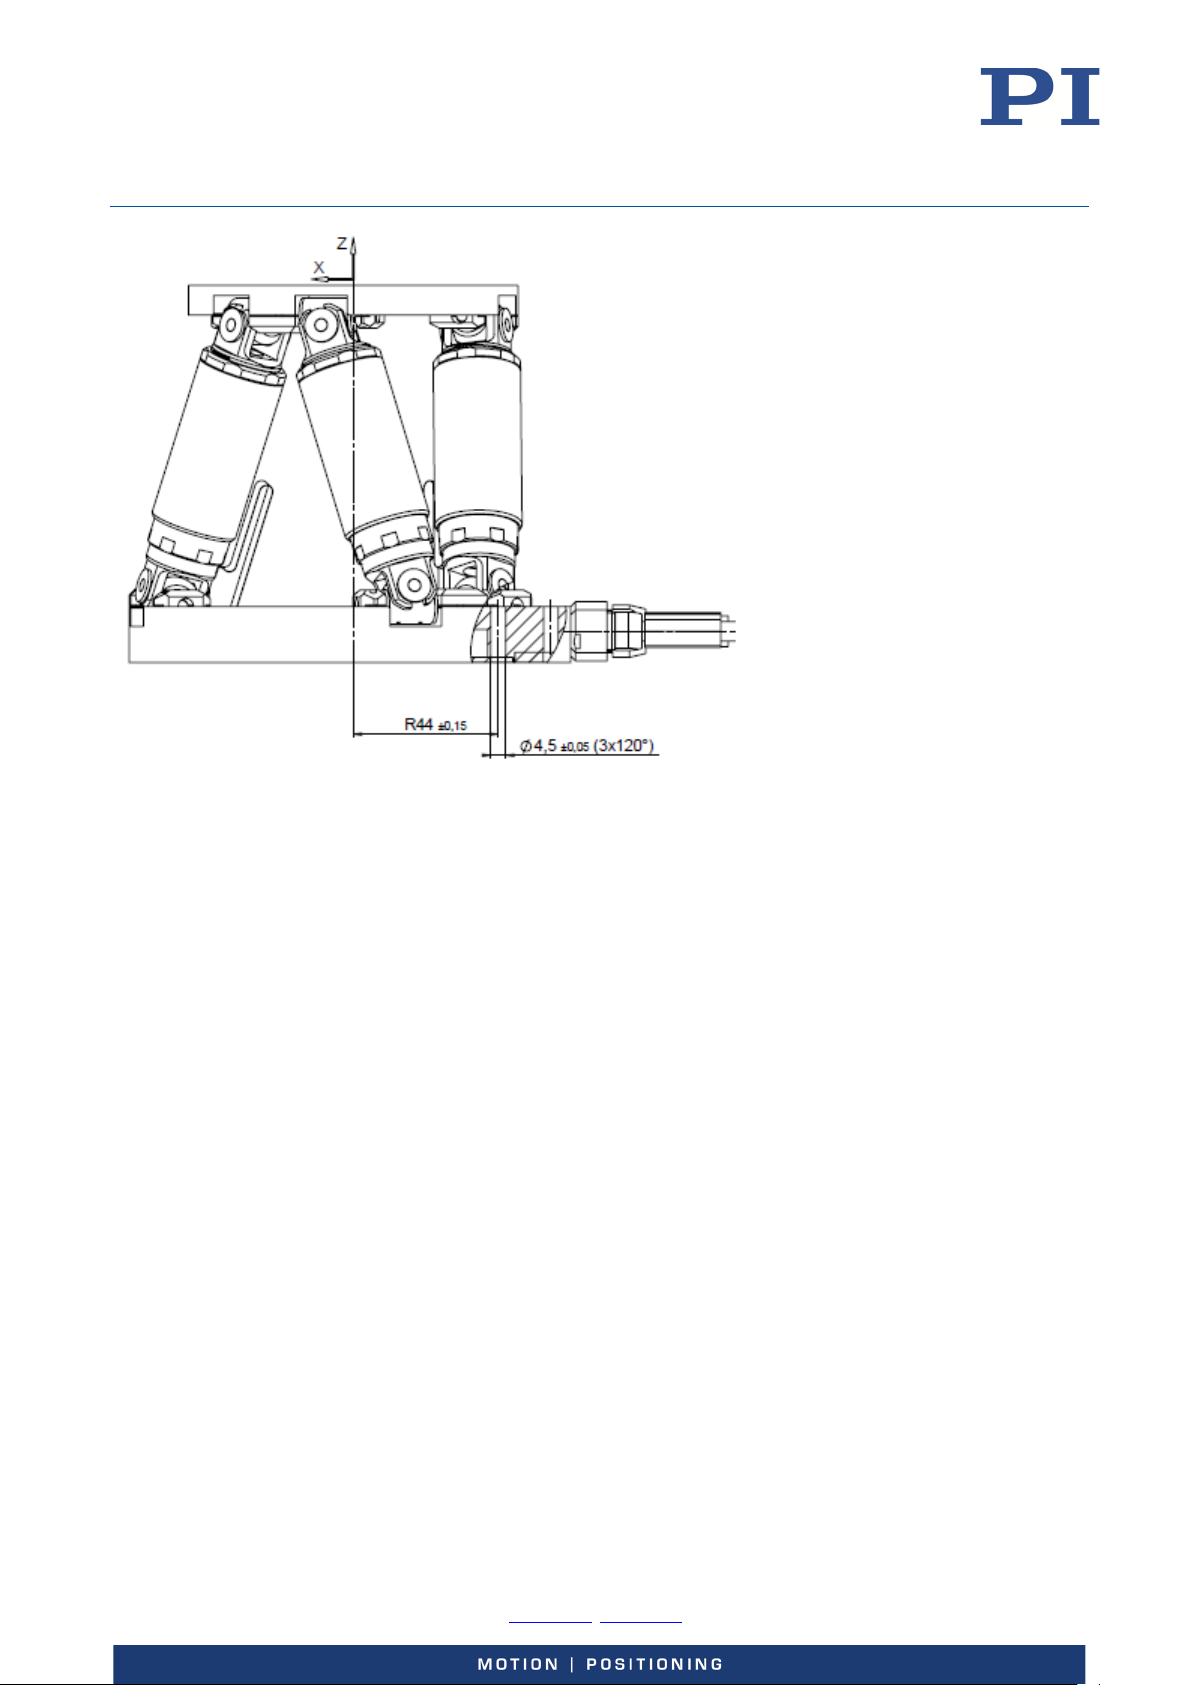
Figure 1: H-811.x2 Hexapod dimensions
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 8
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 8 / 12
Phone +49 721 4846
H-811.D2
H-811.S2
Unit
Tolerance
Active axes
X, Y, Z, θX, θY, θZ
X, Y, Z, θX, θY, θZ
Motion and positioning
Travel range* X, Y, Z
±17, ±16, ±6.5
±17, ±16, ±6.5
mm Travel range* θX, θY, θZ
±10, ±10, ±21
±10, ±10, ±21
° Single-actuator design resolution
40
80
nm Min. incremental motion X, Y
0.25
1
µm
typ.
Min. incremental motion Z
0.1
0.5
µm
typ.
Min. incremental motion θX, θY, θZ
3 7 µrad
typ.
Backlash X, Y
0.2 2 µm
typ.
Backlash Z
0.06
0.5
µm
typ.
Backlash θX, θY
4
20
µrad
typ.
Backlash θZ
4
30
µrad
typ.
Repeatability X, Y
±0.15
±0.3
µm
typ.
Repeatability Z
±0.06
±0.1
µm
typ.
Repeatability θX, θY
±2
±4
µrad
typ.
Repeatability θZ
±3
±8
µrad
typ.
Max. velocity X, Y, Z
10
20
mm/s
Max. velocity θX, θY, θZ
250
500
mrad/s
Typ. velocity X, Y, Z
5
10
mm/s
Typ. velocity θX, θY, θZ
120
250
mrad/s
Mechanical properties
Stiffness X / Y
0.7
0.7
N/µm
Stiffness Z
8 8 N/µm
Load (base plate horizontal / any
orientation)
5 / 2.5
5 / 2.5
kg
max.
Holding force, de-energized (base
plate horizontal / any orientation)
15 / 2.5
15 / 2.5
N
max.
Motor type
Brushless DC motor
Brushless DC motor
Miscellaneous
Operating temperature range
0 to 50
0 to 50
°C
Material
Stainless steel,
aluminum
Stainless steel,
aluminum
Mass
2.2
2.2
kg
±5 %
Cable length
2 2 m
±10 mm
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
Technical Data
Data Table
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 9
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 9 / 12
Phone +49 721 4846
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
Technical data specified at 20±3°C.
* The travel ranges of the individual coordinates (X, Y, Z, θX, θY, θZ) are interdependent. The
data for each axis in this table shows its maximum travel, where all other axes are at their zero
positions. If the other linear or rotational coordinates are not zero, the available travel may be
less.
Maximum Ratings
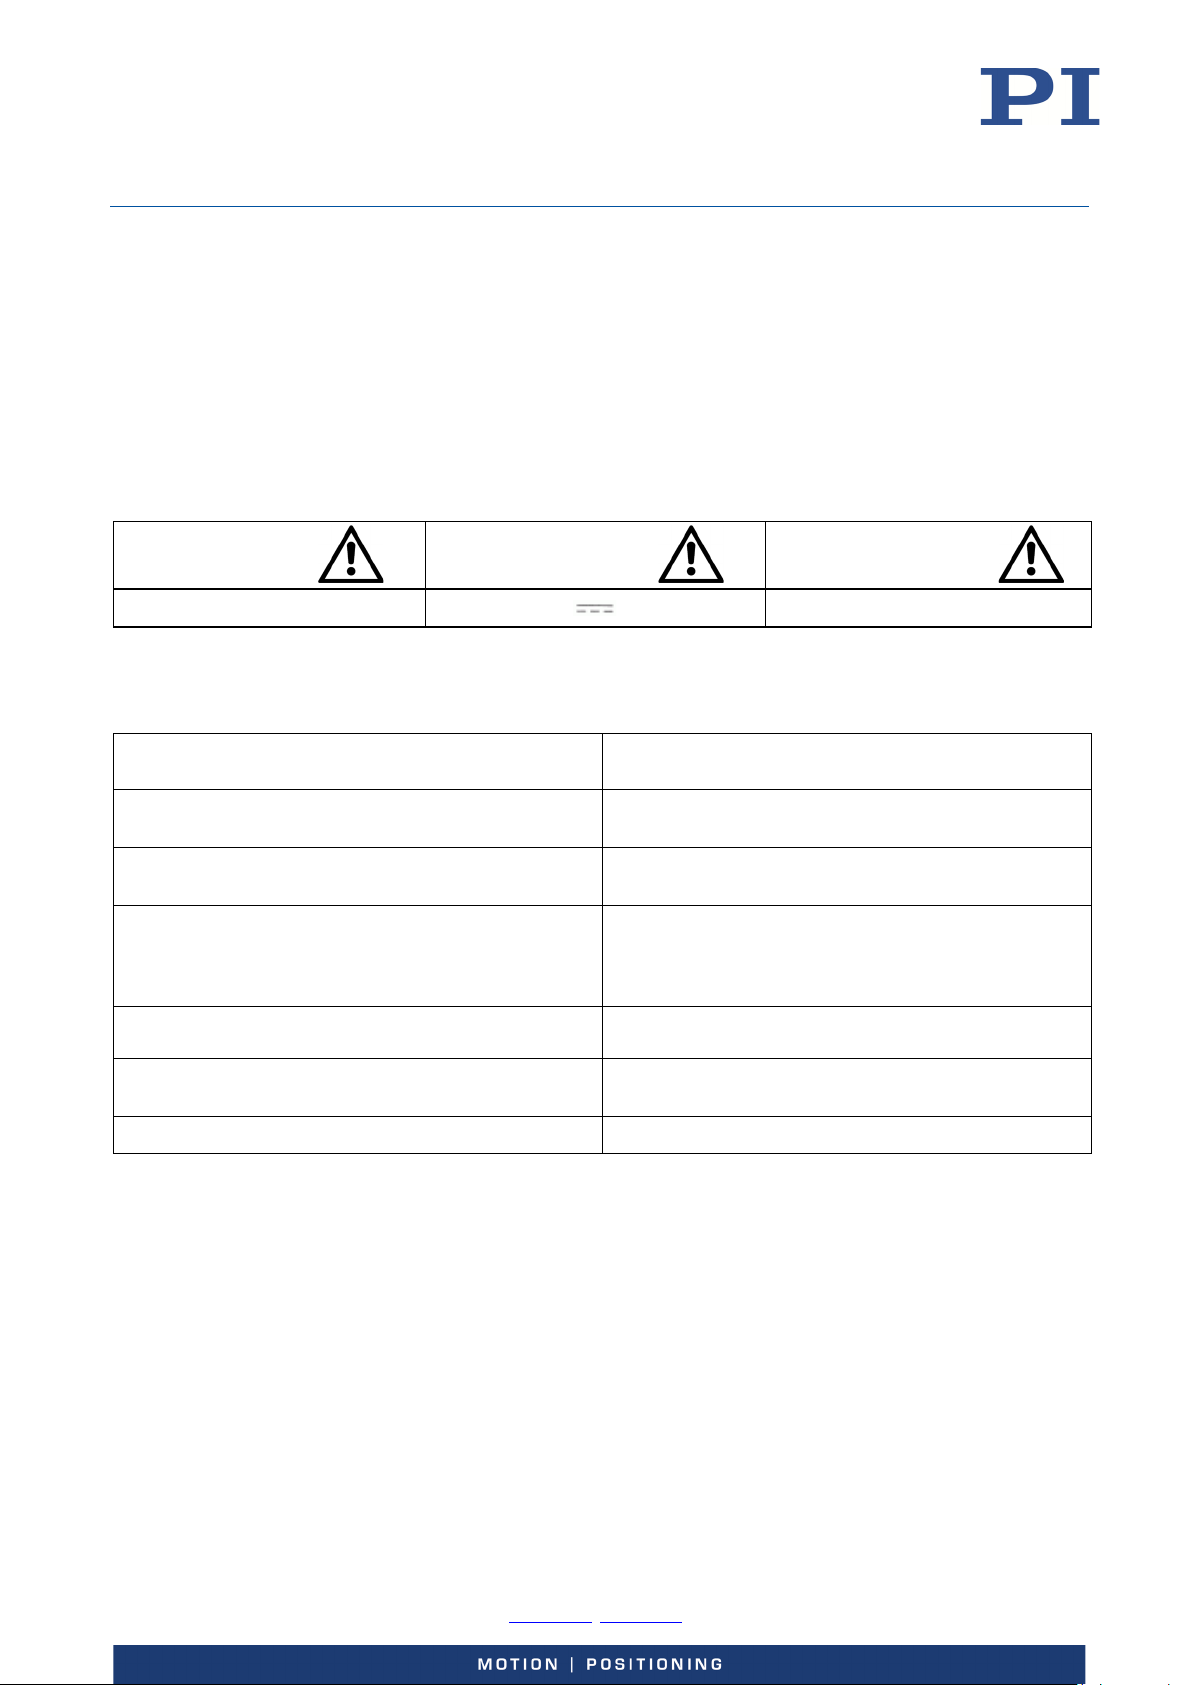
The Hexapod is designed for the following operating data:
Maximum
operating voltage
Maximum operating
frequency (unloaded)
Maximum current
consumption
24 V DC
5 A
Ambient Conditions and Classifications
Degree of pollution: 2
Transport temperature: –25°C to +85°C
Storage temperature: 0 °C to 70 °C
Humidity: Maximum relative humidity of 80% at temperatures
of up to 31°C, linearly decreasing until relative
humidity of 50% at 40°C
Degree of protection according to IEC 60529: IP20
Area of application: For indoor use only
Maximum altitude: 2000 m
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 10
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 10 / 12
Phone +49 721 4846
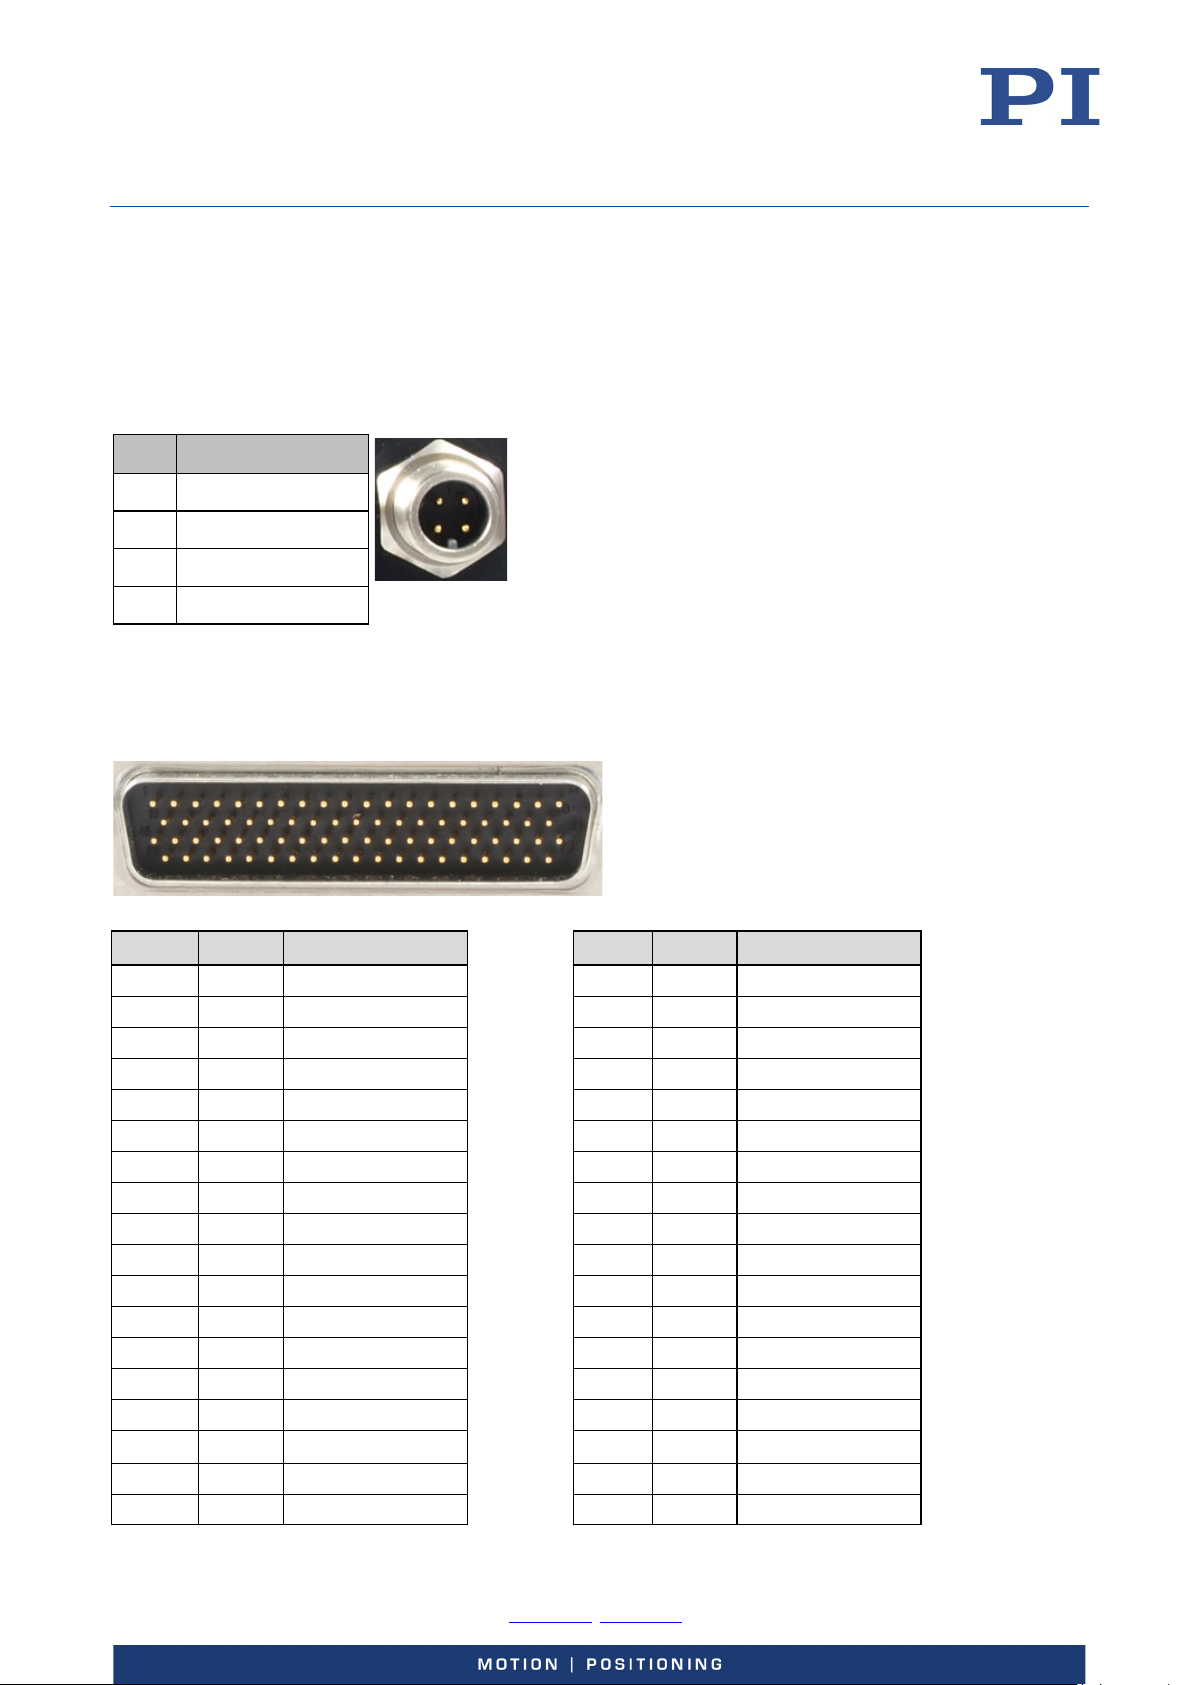
Pin*
Pin*
Signal*
Pin*
Pin*
Signal*
1
CH1 Sign
40
CH1 MAGN
21
CH1 Ref
60
CH1 LimP
2
CH1 VDD
41
CH1 LimN
22
CH1 A+
61
CH1 B+
3
CH1 A-
42
CH1 B-
23
GND
62
GND
4 CH2 Sign
43
CH2 MAGN
24
CH2 Ref
63
CH2 LimP
5
CH2 VDD
44
CH2 LimN
25
CH2 A+
64
CH2 B+
6
CH2 A-
45
CH2 B-
26
GND
65
GND
7
CH3 Sign
46
CH3 MAGN
27
CH3 Ref
66
CH3 LimP
8
CH3 VDD
47
CH3 LimN
28
CH3 A+
67
CH3 B+
9
CH3 A-
48
CH3 B-
29
GND
68
GND
1
20
21
39
40
59
60
78
1
2 3 4
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
Pin Assignment
Power Supply
4-pin M12 connector
Pin Function
1 GND
2 GND
3 24 V DC
4 24 V DC
Data Transmission
HD Sub-D 78 (m) connector
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 11
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 11 / 12
Phone +49 721 4846
Pin*
Pin*
Signal*
Pin*
Pin*
Signal*
10
CH4 Sign
49
CH4 MAGN
30
CH4 Ref
69
CH4 LimP
11
CH4 VDD
50
CH4 LimN
31
CH4 A+
70
CH4 B+
12
CH4 A-
51
CH4 B-
32
GND
71
GND
13
CH5 Sign
52
CH5 MAGN
33
CH5 Ref
72
CH5 LimP
14
CH5 VDD
53
CH5 LimN
34
CH5 A+
73
CH5 B+
15
CH5 A-
54
CH5 B-
35
GND
74
GND
16 CH6 Sign
55 CH6 MAGN
36
CH6 Ref
75
CH6 LimP
17 CH6 VDD
56 CH6 LimN
37
CH6 A+
76
CH6 B+
18 CH6 A-
57 CH6 B-
38
GND
77
GND
19 Reserved
58
Brake/Enable drive
39
GND
78
GND
20 24 V output
59
Power good 24 V
input
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
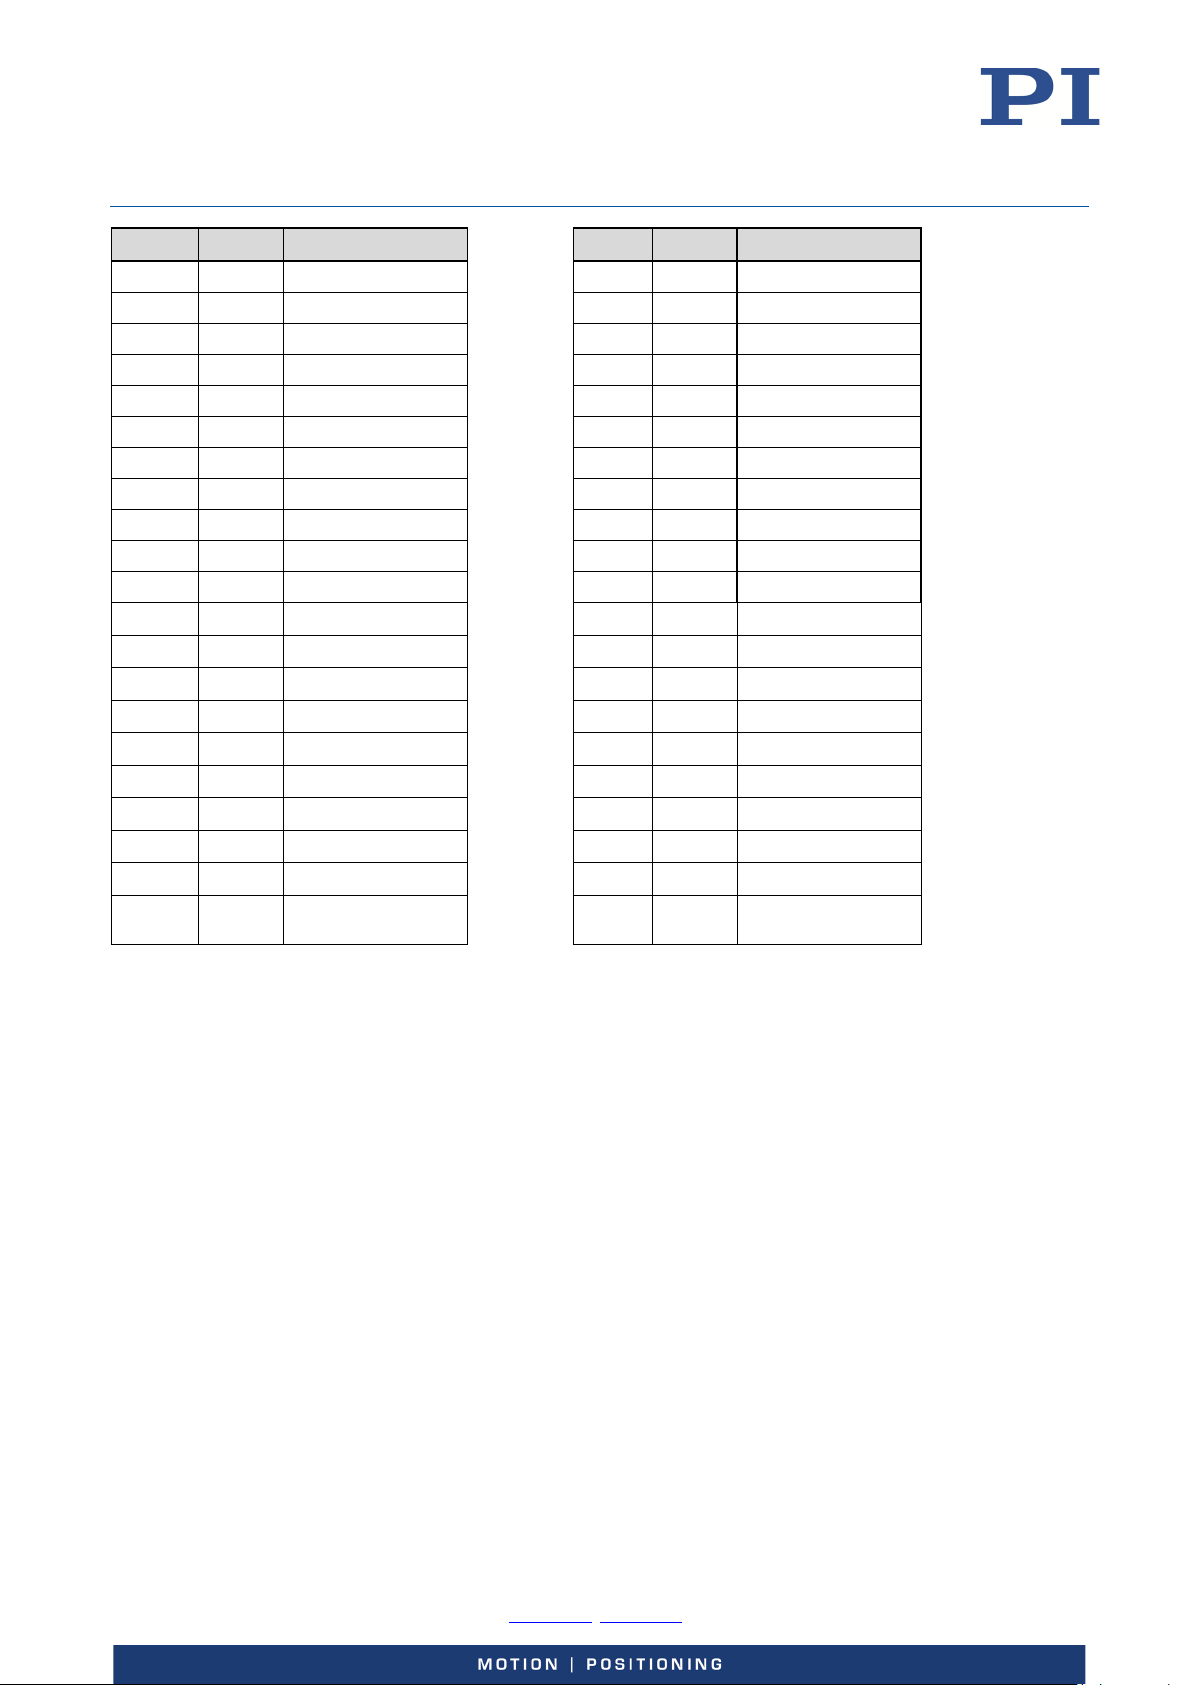
* Pin assignment of the C-887.5xx Hexapod controller. Since not all signals are required for all Hexapod models, some
pins may be not assigned with your Hexapod model.
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 12
Technical Note
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany Page 12 / 12
Phone +49 721 4846
H811T0019, valid for H-811.D2 and H-811.S2
Bro, MMa, 9/5/2016
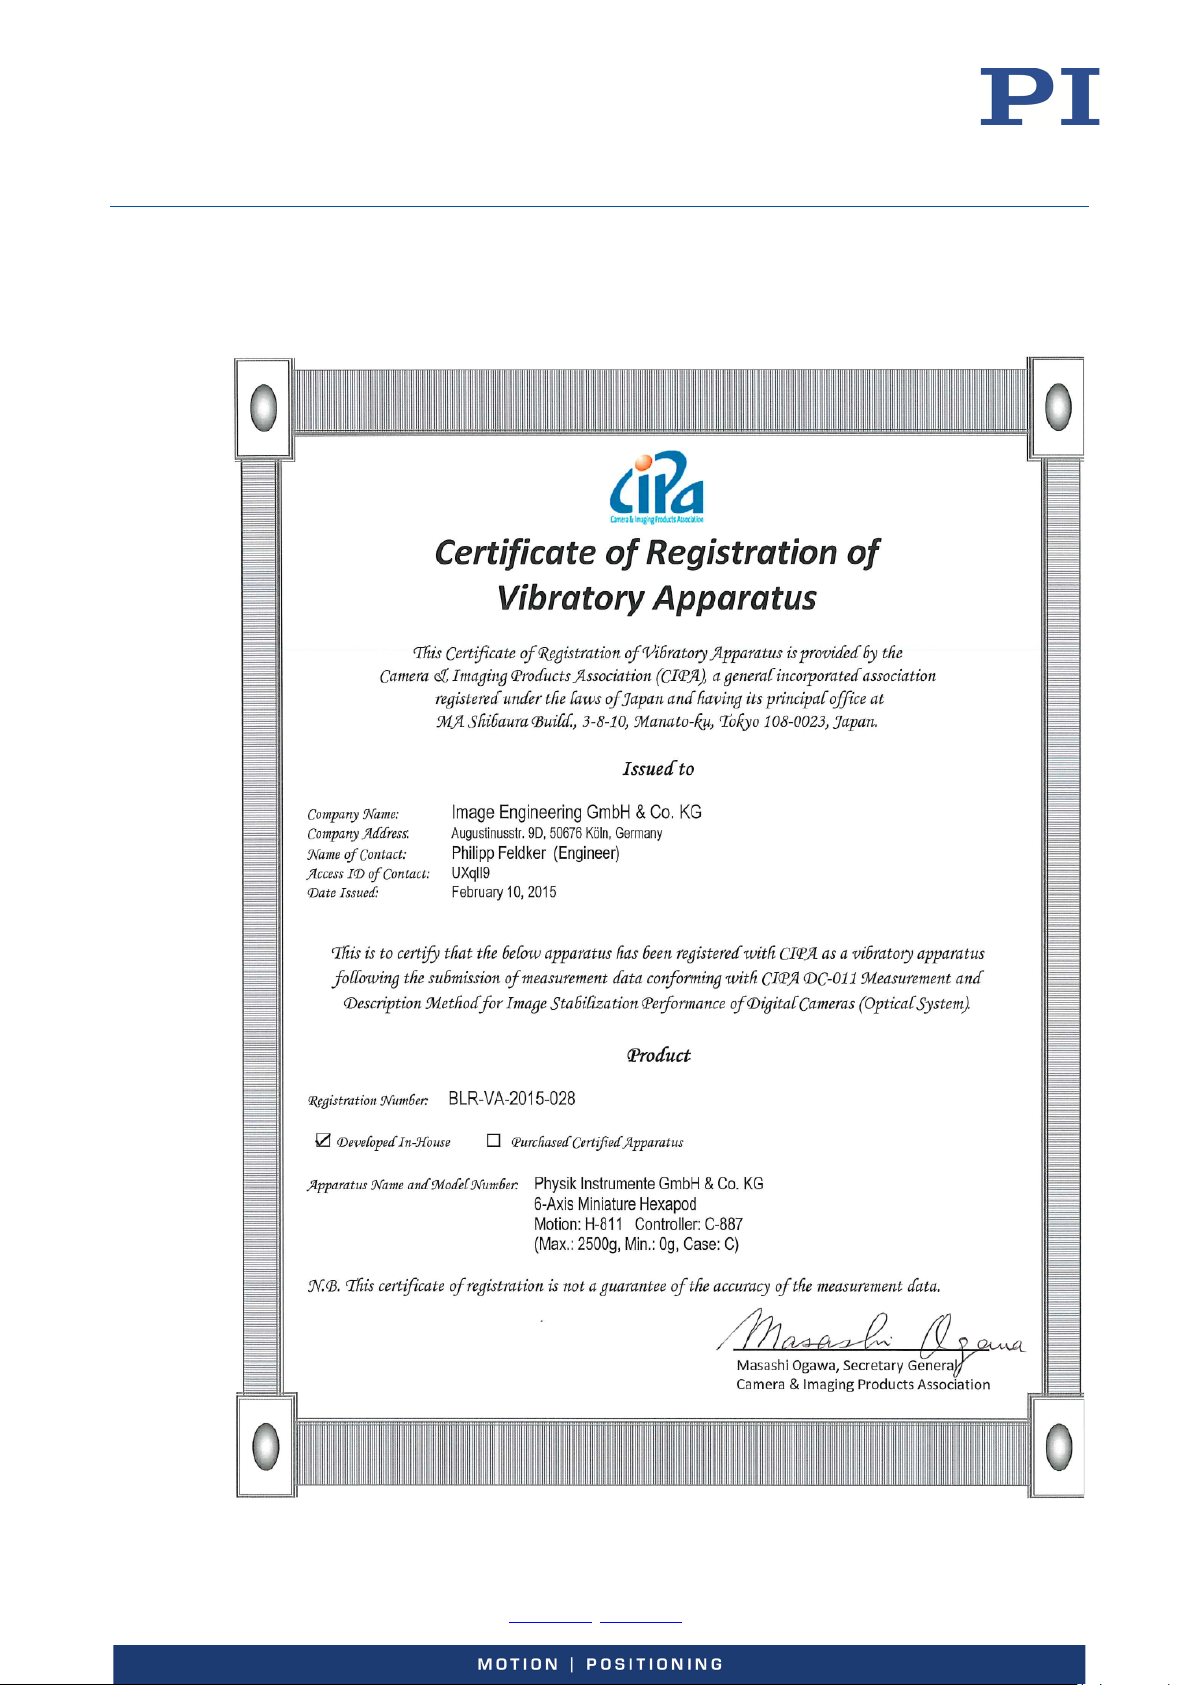
CIPA Certificate
The product has been certified for camera test applications according to the CIPA association.
-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
 Loading...