

Page 1
REGAL-BELOIT
Variable Speed AC Motor Drives
Installation and Operation Manual
Page 2
Manual Number: SB182
TABLE OF CONTENTS
1.0 GENERAL . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .1
2.0 SpinMaster™ DIMENSIONS . . . . . . . . . . . . . . . . . . . . . . . . . . . .3
4.0 SpinMaster™ SPECIFICATIONS . . . . . . . . . . . . . . . . . . . . . . . . .4
5.0 SpinMaster™ RATINGS . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .5
6.0 INSTALLATION . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .6
7.0 INPUT AC POWER REQUIREMENTS . . . . . . . . . . . . . . . . . . . . . .7
8.0 POWER WIRING . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .10
9.0 SpinMaster™ POWER WIRING DIAGRAM . . . . . . . . . . . . . . . .11
10.0 CONTROL WIRING . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .12
11.0 SpinMaster™ CONTROL WIRING DIAGRAMS . . . . . . . . . . . . . .15
12.0 INITIAL POWER UP AND MOTOR ROTATION . . . . . . . . . . . . . .19
13.0 PROGRAMMING THE SpinMaster™ DRIVE . . . . . . . . . . . . . . .21
14.0 PARAMETER MENU . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .25
15.0 DESCRIPTION OF PARAMETERS . . . . . . . . . . . . . . . . . . . . . . . .28
16.0 TROUBLESHOOTING . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .43
17.0 SpinMaster™ DISPLAY MESSAGES . . . . . . . . . . . . . . . . . . . . . .45
Page 3
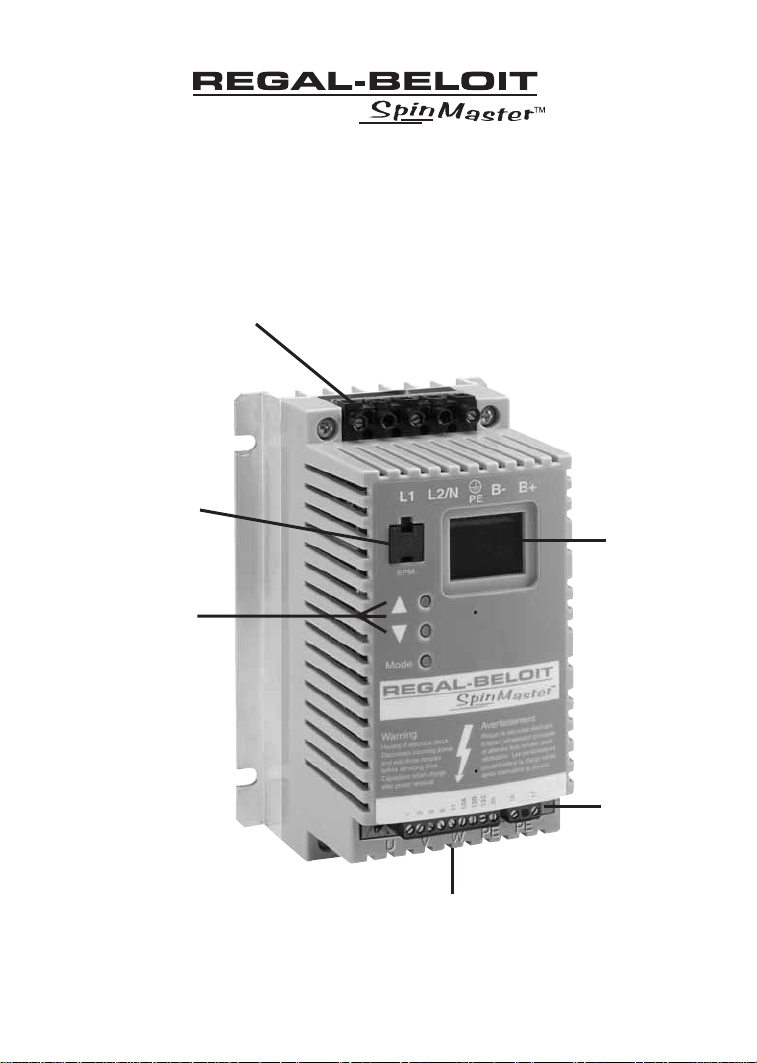
SUB-MICRO DRIVE
INPUT POWER
TERMINALS
ELECTRONIC
PROGRAMMING
MODULE (EPM)
PROGRAMMING
BUTTONS
OUTPUT (MOTOR)
TERMINALS
3-DIGIT LED
DISPLAY
CONTROL
TERMINAL
STRIP
Page 4
IMPORTANT NOTICE
The following , and information is supplied to you for
your protection and to provide you with many years of tr ouble free and safe operation of your
Marathon Electric product.
• Hazard of electrical shock! Capacitors retain charge after power is removed. Disconnect
incoming power and wait until the voltage between terminals B+ and B- is 0 VDC before
servicing the drive.
• Hazard of electrical shock! Wait three minutes after disconnecting incoming power
before servicing drive. Capacitors retain charge after power is removed.
• DRIVES MUST NOT BE INSTALLED WHERE SUBJECTED TO ADVERSE ENVIRONMENTAL
CONDITIONS SUCH AS: COMBUSTIBLE, OILY, OR HAZARDOUS VAPORS OR DUST;
EXCESSIVE MOISTURE OR DIRT; VIBRATION; EXCESSIVE AMBIENT TEMPERATURES. CONSULT REGAL BELOIT CORPORATION FOR MORE INFORMATION ON THE SUITABILITY OF
A DRIVE TO A PARTICULAR ENVIRONMENT.
• Automatic starting of equipment may cause damage to equipment and / or injury to
personnel! Automatic start should only be used on equipment that is inaccessible to
personnel.
• Severe damage to the drive can result if it is operated after a long period of storage or
inactivity without reforming the DC bus capacitors!
• Do not connect incoming AC power to output terminals U, V, or W, or terminals B+, B-!.
Severe damage to the drive will result.
• When operating in JOG mode, the STOP signal and the AUXILIARY STOP function (see
Parameters 10-12), or the STOP key on the optional remote keypad WILL NOT
stop the
drive. To stop the drive, remove the JOG command.
• JOG REVERSE will operate the drive in reverse rotation even if ROTATION DIRECTION
(Parameter 17) is set to FORWARD ONLY.
• DO NOT connect incoming AC power to output terminals U, V, and W or terminals B+,
B-! Severe damage to the drive will result. Do not continuously cycle input power to the
drive more than once every two minutes. Damage to the drive will result.
• Do not remove the EPM while power is applied to the drive. Damage to the EPM and/or
drive may result.
• This product can cause a DC current in the protective conductor where a
residual current device (RCD) is used for protection in case of direct or indirect contact,
only an RCD of Type B is allowed on the supply side of this product. Otherwise
another protective measure shall be applied, such as separation from the environment
by double or reinforced insulation, or isolation from the supply system by a transformer.
• Leakage current may exceed 3.5mA AC. Minimum size of the protective earth
conductor shall comply with local safety regulations for high leakage current equipment.
• Consult qualified personnel with questions. All electrical repairs must be performed by
trained and qualified personnel only.
Resale of Goods:
In the event of the resale of any of the goods, in whatever form, Resellers/Buyers will include the following
language in a conspicuous place and in a conspicuous manner in a written agreement covering such sale:
The manufacturer makes no warranty or representations, express or implied, by operation of law or
otherwise, as the merchantability or fitness for a particular purpose of the goods sold hereunder.
Buyer acknowledges that it alone has determined that the goods purchased hereunder will suitably
meet the requirements of their intended use. In no event will the manufacturer be liable for
consequential, incidental or other damages. Even if the repair or replacement remedy shall be
deemed to have failed of its essential purpose under Section 2-719 of the Uniform Commercial Code,
the manufacturer shall have no liability to Buyer for consequential damages.
Resellers/Buyers agree to also include this entire document including the warnings and cautions above in
a conspicuous place and in a conspicuous manner in writing to instruct users on the safe usage of the
product.
WARNING
WARNING
CAUTION
CAUTION
DANGER
DANGER
Page 5
1.0 GENERAL
1.1 PRODUCTS COVERED IN THIS MANUAL
This manual covers the REGAL BELOIT CORPORATION SpinMaster™ Variable Frequency Drive.
1.2 PRODUCT CHANGES
REGAL BELOIT CORPORATION reserves the right to discontinue or make modifications to the
design of its products without prior notice, and holds no obligation to make modifications to
products sold previously. REGAL BELOIT CORPORATION also holds no liability for losses of any
kind which may result from this action. Instruction manuals are available for download from
www.marathonelectric.com.
1.3 WARRANTY
REGAL BELOIT CORPORATION warrants the SpinMaster™ AC motor control to be free of
defects in material and workmanship for a period of 24 months from the date of manufacture.
If a SpinMaster™ motor control, under normal use, becomes defective within the stated
warranty time period, contact Customer Service for instructions on obtaining a warranty
replacement unit. REGAL BELOIT CORPORATION reserves the right to make the final
determination as to the validity of a warranty claim, and sole obligation is to repair or replace
only components which have been rendered defective due to faulty material or workmanship.
No warranty claim will be accepted for components which have been damaged due to
mishandling, improper installation, unauthorized repair and/or alteration of the product,
operation in excess of design specifications or other misuse, or improper maintenance. REGAL
BELOIT CORPORATION makes no warranty that its products are compatible with any other
equipment, or to any specific application, to which they may be applied and shall not be held
liable for any other consequential damage or injury arising from the use of its products.
This warranty is in lieu of all other warranties, expressed or implied. No other
person, firm or corporation is authorized to assume, for REGAL BELOIT
CORPORATION, any other liability in connection with the demonstration or
sale of its products.
1.4 RECEIVING
Inspect all cartons for damage which may have occurred during shipping. Carefully unpack
equipment and inspect thoroughly for damage or shortage. Report any damage to carrier
and/or shortages to supplier. All major components and connections should be examined for
damage and tightness, with special attention given to PC boards, plugs, knobs and switches.
1.5 SAFETY INFORMATION
General
All operations concerning installation and commissioning, as well as maintenance, must be
carried out by qualified, skilled personnel (IEC 364 and CENELEC HD 384 or DIN VDE 0100
1
Page 6
and IEC report 664 or DIN VDE 0110 and national regulations for the prevention of accidents
must be observed).
According to this basic safety information, qualified skilled personnel are persons who are
familiar with the installation, assembly, commissioning, and operation of the product and who
have the qualifications necessary for their occupation.
APPLICATION AS DIRECTED
Drive controllers are components which are designed for installation in electrical systems or
machinery. They are not to be used as appliances. They are intended exclusively for
professional and commercial purposes according to EN 61000-3-2.
When installing the drive controllers in machines, commissioning (i.e. the starting of operation
as directed) is prohibited until it is proven that the machine complies with the regulations of
the EC Directive 98/37/EC (Machinery Directive); EN 60204 must be observed. Commissioning
(i.e. starting of operation as directed) is only allowed when there is compliance with the EMC
Directive (89/336/EEC).
The drive controllers meet the requirements of the Low Voltage Directive 73/23/EEC. The
harmonized standards of the series EN50178/DIN VDE 0160 apply to the controllers.
NOTE: This is a product of the restricted sales distribution class according to EN61800-3. In a
domestic environment this product may cause radio interference, in which case the user may
be required to take adequate measures.
ELECTRICAL CONNECTION
When working on live drive controllers, applicable national regulations for the prevention of
accidents (e.g. VBG 4) must be observed.
The electrical installation must be carried out according to the appropriate regulations (e.g.
cable size, fuses, PE connection).
This manual contains information about installation in compliance with EMC (shielding,
grounding, filters and cables). These notes must also be observed for CE-marked controllers.
The manufacturer of the system or machine is responsible for compliance with the required
limit values demanded by EMC legislation.
1.6 CUSTOMER MODIFICATION
REGAL BELOIT CORPORATION, it’s sales representatives and distributors, welcome the
opportunity to assist our customers in applying our products. Many customizing options are
available to aid in this function. REGAL BELOIT CORPORATION cannot assume responsibility for
any modifications not authorized by its engineering department.
2
Page 7
3
INPUT INPUT
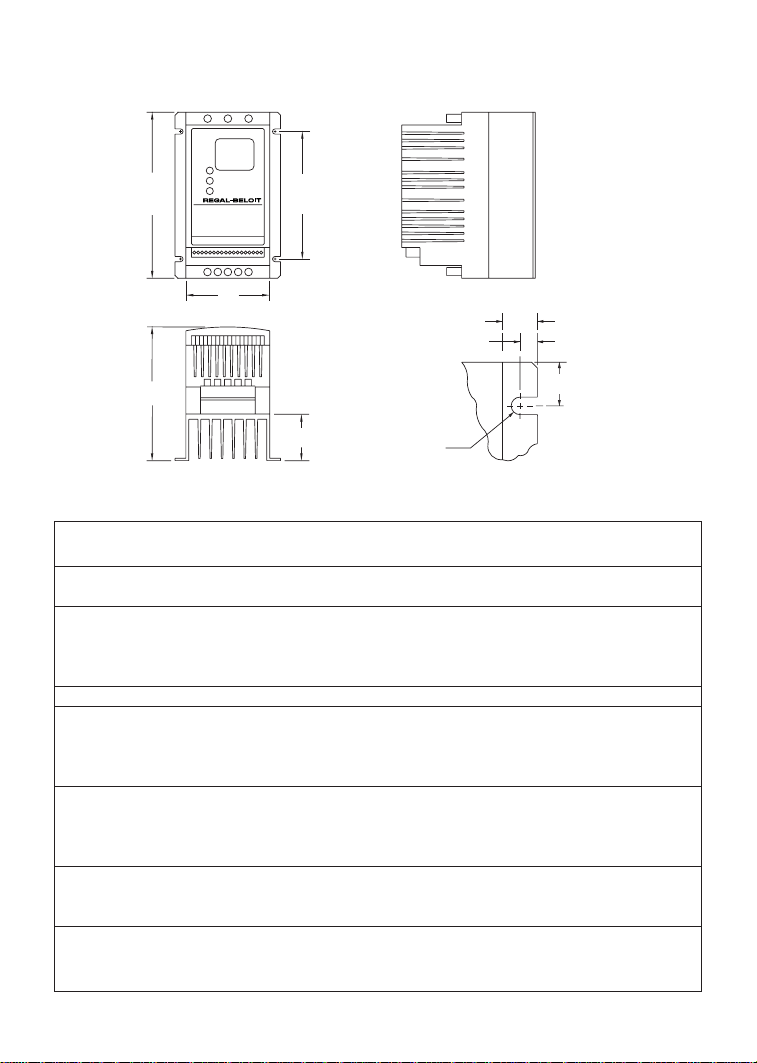
HP kW VOLTAGE PHASE MODEL W D P
0.33 0.25
120 1 T201 2.88 (74) 3.27 (83) 0.28 (7)
208/240 1 T211 2.88 (74) 3.27 (83) 0.28 (7)
120 1 T202 2.88 (74) 3.27 (83) 0.28 (7)
0.5 0.37
208/240 1 T212 2.88 (74) 3.27 (83) 0.28 (7)
208/240 3 T222 2.88 (74) 3.27 (83) 0.28 (7)
400/480 3 T232 2.88 (74) 3.94 (100) 0.80 (20)
0.75 0.55 208/240 1 T213 2.88 (74) 3.62 (92) 0.63 (16)
120 1 T204 3.76 (95) 4.88 (124) 1.50 (38)
1 0.75
208/240 1 T214 2.88 (74) 3.62 (92) 0.63 (16)
208/240 3 T224 2.88 (74) 3.62 (92) 0.63 (16)
400/480 3 T234 2.88 (74) 4.74 (120) 1.60 (41)
120 1 T205 3.75 (95) 4.88 (124) 1.50 (38)
1.5 1.1
208/240 1 T215 3.76 (95) 4.88 (124) 1.50 (38)
208/240 3 T225 2.88 (74) 5.55 (141) 2.56 (65)
400/480 3 T235 2.88 (74) 5.74 (146) 2.56 (65)
208/240 1 T216 3.76 (95) 4.88 (124) 1.50 (38)
2 1.5 208/240 3 T226 2.88 (74) 5.55 (141) 2.56 (65)
400/480 3 T236 2.88 (74) 5.74 (146) 2.56 (65)
208/240 1 T217 3.76 (95) 5.55 (141) 2.18 (55)
3 2.2 208/240 3 T227 3.76 (95) 5.55 (141) 2.18 (55)
400/480 3 T237 3.76 (95) 6.74 (171) 2.56 (65)
2.0 SpinMaster™ DIMENSIONS
D
P
0.69" (17.5mm)
0.18" (4.6mm)
0.38" (9.5mm)
0.19" (4.8mm)
Dia. Slot
Mounting T ab Detail
5.75"
(146mm)
W
4.37"
(111mm)
Page 8
4
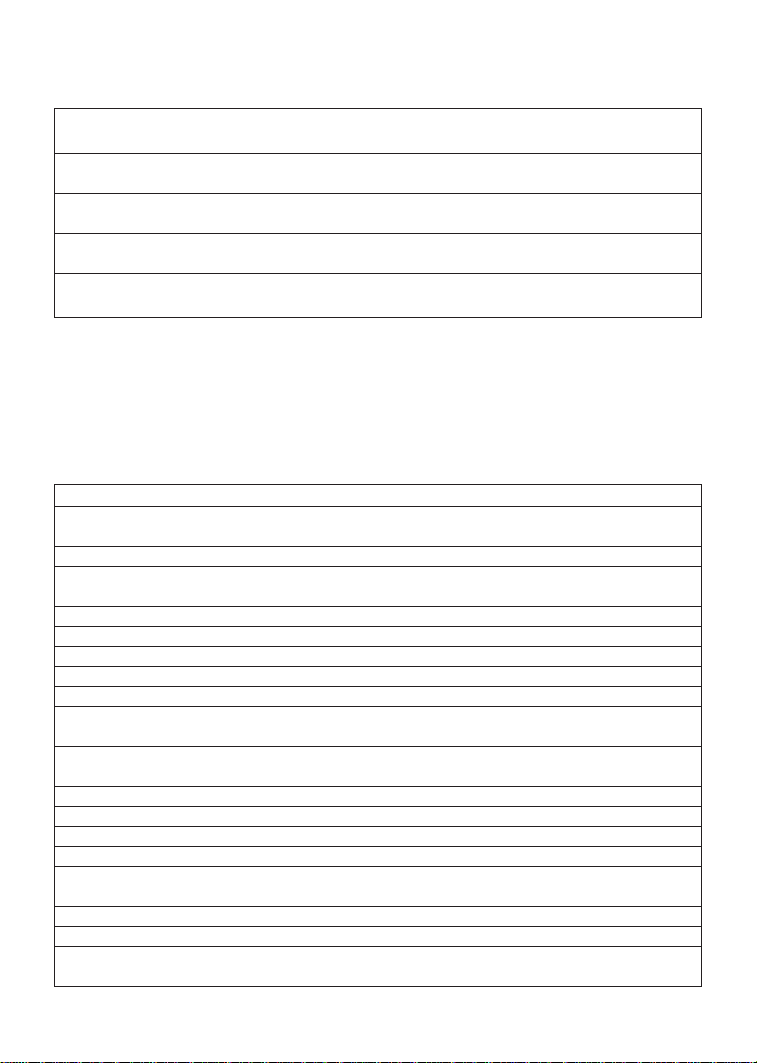
4.0 SpinMaster™ SPECIFICATIONS
Storage Temperature -20° to 70° C
Ambient Operating Temperature 0° to 40° C (derate 5% per °C above 40° C,
up to 55° C max)
Ambient Humidity <95% (non-condensing)
Maximum Altitude 3300 ft (1000m) above sea level
(derate 5% per additional 3300 ft.)
Input Line Voltages 120, 208/240, 400/480 Vac
Input Voltage Tolerance +10%, -15%
Input Frequency Tolerance 48 to 62 Hz
Output Wave Form Sine Coded PWM
Output Frequency 0 - 240 Hz
Carrier Frequency 4 kHz to 10 kHz (10 kHz requires derating:
see Parameter P02)
Service Factor 1.00 (up to 8 kHz carrier, derate for 10 kHz;
see Parameter P02)
Efficiency Up to 98%
Power Factor (displacement) 0.96 or better
Overload Current Capacity 150% for 60 seconds, 180% for 30 seconds
Speed Reference Follower 0 - 10 VDC, 4 - 20 mA
Digital Outputs (1) Normally open relay; contacts rated 3 amps at 250 Vac
(1) Digital output (current-sourcing); rated 50 mA at 12 VDC
Earth Leakage Current (EN 50178) <3.5 mA to PE
Conformity CE: Low voltage directive (73/23/EEC)
Approvals UL508: Underwriters laboratories -
Power Conversion Equipment
INPUT INPUT
HP kW VOLTAGE PHASE MODEL W D P
5 4.0
208/240 3 T228 5.02 (128) 6.74 (171) 3.40 (86)
400/480 3 T238 3.76 (95) 6.74 (171) 3.40 (86)
7.5 5.5
208/240 3 T229 5.02 (128) 7.18 (182) 3.40 (86)
400/480 3 T239 3.76 (95) 6.74 (171) 3.40 (86)
10 7.5
208/240 3 T220 5.02 (128) 7.18 (182) 3.40 (86)
400/480 3 T230 5.02 (128) 7.18 (182) 3.40 (86)
15 11
208/240 3 T221 6.68 (170) 8.00 (203) 3.40 (86)
400/480 3 T231 5.02 (128) 7.18 (182) 3.60 (91)
2.0 SpinMaster™ DIMENSIONS (con’t.)
Page 9
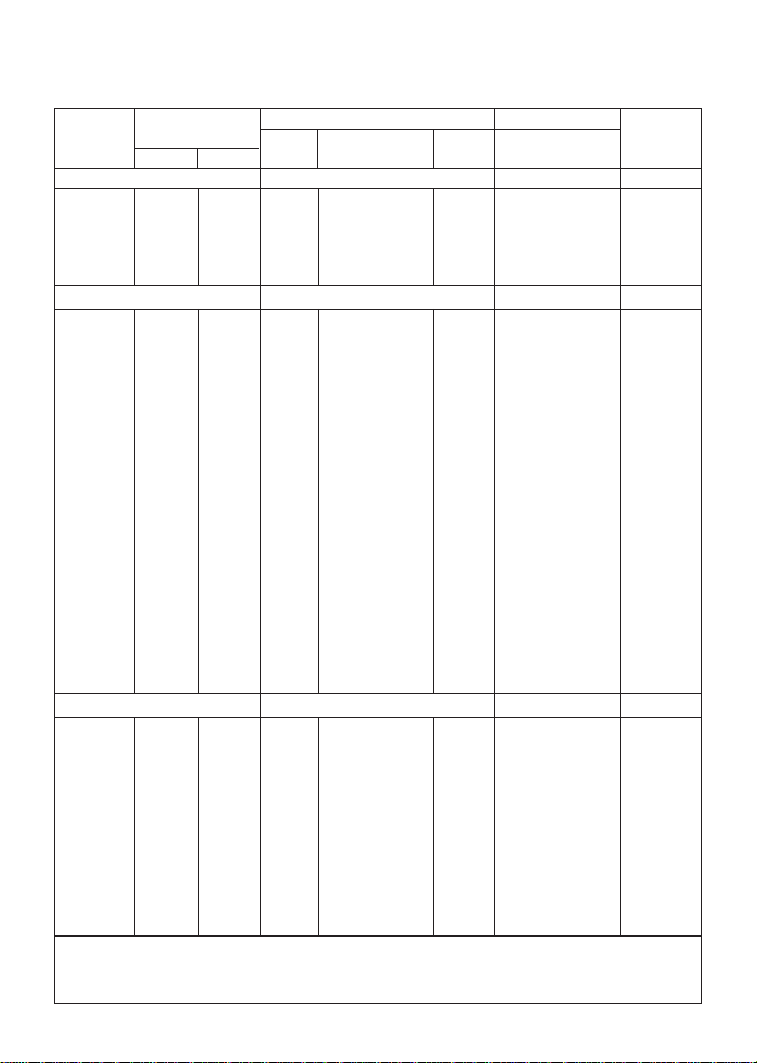
FOR MOTORS INPUT (50-60 Hz) OUTPUT (3 Phase) HEAT
MODEL RATED INPUT CURRENT POWER CURRENT LOSS
1
NUMBER HP kW PHASE (AMPS) (kVA) (AMPS) (WATTS)
120 Vac INPUT MODELS 120 Vac 0 - 230 Vac
T201 0.33 0.25 1 6.8 0.8 1.7 29
T202 0.50 0.37 1 9.2 1.1 2.4 33
T204 1 0.75 1 16.6 2.0 4.2 57
T205 1.5 1.1 1 24 2.9 6.0 86
208/240 VAC INPUT MODELS 208/240 Vac 0 - 208/230 Vac
T211 0.33 0.25 1 3.9/3.4 0.8 1.9/1.7 23
T212 0.50 0.37 1 5.8/5.0 1.2 2.8/2.4 31
T222 0.50 0.37 3 3.1/2.7 1.1 2.8/2.4 31
T213 0.75 0.55 1 6.9/6.0 1.4 3.7/3.2 34
T214 1 0.75 1 10.6/9.2 2.2 4.8/4.2 47
T224 1 0.75 3 5.8/5.1 2.1 4.8/4.2 47
T215 1.5 1.1 1 13.9/12.0 2.9 6.9/6.0 68
T225 1.5 1.1 3 8.0/6.9 2.9 6.9/6.0 68
T216 2 1.5 1 18.4/16.0 3.1 8.1/7.0 71
T226 2 1.5 3 9.1/7.9 3.3 8.1/7.0 71
T217 3 2.2 1 24/21 4.1 11.0/9.6 108
T227 3 2.2 3 12.4/10.8 4.5 11.0/9.6 108
T228 5 4.0 3 19.6/17.1 7.1 17.5/15.2 173
T229 7.5 5.5 3 28/25 10.3 25/22 286
T220 10 7.5 3 34/32 13.1 30/28 379
T221 15 11 3 54/48 20.0 48/42 476
400/480 VAC INPUT MODELS 400/480 Vac 0 - 400/480 Vac
T232 0.50 0.37 3 1.6/1.4 1.1 1.3/1.1 31
T234 1 0.75 3 3.0/2.5 2.1 2.5/2.1 47
T235 1.5 1.1 3 4.3/3.6 3.0 3.6/3.0 58
T236 2 1.5 3 4.8/4.0 3.3 4.1/3.4 63
T237 3 2.2 3 6.4/5.4 4.5 5.8/4.8 92
T238 5 4.0 3 10.6/8.8 7.1 9.4/7.8 155
T239 7.5 5.5 3 14.2/12.4 10.3 12.6/11.0 254
T230 10 7.5 3 18.1/15.8 13.1 16.1/14.0 310
T231 15 11 3 27/24 20.0 24/21 390
1: Values are worst-case (not typical) for 6kHz carrier frequency at full speed and full
load.
5
5.0 SpinMaster™ RATINGS
Page 10
6.0 INSTALLATION
NOTE: SpinMaster™ drives are intended for inclusion within other equipment, by
professional electrical installers according to EN 61000-3-2. They are not intended for
stand-alone operation.
DRIVES MUST NOT BE INSTALLED WHERE SUBJECTED TO ADVERSE ENVIRONMENTAL CONDITIONS SUCH AS: COMBUSTIBLE, OILY, OR HAZARDOUS VAPORS OR
DUST; EXCESSIVE MOISTURE OR DIRT; VIBRATION; EXCESSIVE AMBIENT TEMPERATURES.
CONSULT REGAL BELOIT CORPORATION FOR MORE INFORMATION ON THE SUITABILITY OF A
DRIVE TO A PARTICULAR ENVIRONMENT.
SpinMaster™ models are suitable for UL pollution degree 2 environment only, and MUST be
installed in an electrical enclosure which will provide complete mechanical protection and will
maintain the internal temperature within the drive’s ambient operating temperature rating. All
drives models MUST be mounted in a vertical position for proper heatsink cooling.
Maintain a minimum spacing around the drive of at least 1 inch (25mm) on each side and 2
inches (50mm) on the top and bottom for units up to 5 HP (4kW), and 2 inches (50mm) on
each side and 4 inches (100mm) on the top and bottom for larger units. Allow more spacing
if the drive is mounted next to other heat-producing equipment. Do not mount drives above
other drives or heat producing equipment. Fans or blowers should be used to insure proper
cooling in tight quarters.
In order to properly size an enclosur e, the heat generated by the drive(s) must be known. Refer
to the HEAT LOSS columns in Section 5.0 - SpinMaster™ RATINGS. An enclosure manufacturer
can then determine the required enclosure size based on the total heat generated inside the
enclosure (from the drive(s) and other heat sources), the maximum allowable temperature
inside the enclosure, the maximum ambient temperature outside the outside the enclosure,
and the enclosure properties.
The SpinMaster™ is UL approved for solid state motor overload protection. Therefore, a separate thermal overload relay is not required for single motor applications.
6.1 INSTALLATION AFTER A LONG PERIOD OF STORAGE
Severe damage to the drive can result if it is operated after a long period of
storage or inactivity without reforming the DC bus capacitors!
If input power has not been applied to the drive for a period of time exceeding three years
(due to storage etc), the electrolytic DC bus capacitors within the drive can change internally,
resulting in excessive leakage current. This can result in premature failure of the capacitors if
the drive is operated after such a long period of inactivity or storage.
In order to reform the capacitors and prepare the drive for operation after a long period of
inactivity, apply input power to the drive for 8 hours prior to actually operating the motor.
6
WARNING
WARNING
Page 11
7
7.0 INPUT AC POWER REQUIREMENTS
Hazard of electrical shock! Capacitors retain charge after power is removed.
Disconnect incoming power and wait until the voltage between terminals B+ and B- is 0 VDC
before servicing the drive.
The input voltage must match the nameplate voltage rating of the drive. Voltage fluctuation
must not vary by greater than 10% overvoltage or 15% undervoltage.
NOTE: Drives with dual input voltage ratings must be programmed for the proper supply
voltage (refer to Parameter 01 - LINE VOLTAGE SELECTION in Section 15.0 - DESCRIPTION OF
PARAMETERS).
The drive is suitable for use on a circuit capable of delivering not more than 5,000 RMS
symmetrical amperes at the drive’s rated voltage.
If the kVA rating of the AC supply transformer is greater than 10 times the input kVA rating of
the drive(s), an isolation transformer or 2-3% input line reactor must be added to the line side
of the drive(s).
Three phase voltage imbalance must be less than 2.0% phase to phase. Excessive phase to
phase imbalance can cause severe damage to the drive.
Motor voltage should match line voltage in normal applications. The drive’s maximum output
voltage will equal the input voltage. Use extreme caution when using a motor with a voltage
rating which is different from the input line voltage.
7.1 INPUT VOLTAGE RATINGS
T200 Series drives are rated for 120 Vac, single phase, 50-60 Hz input. The drive will function
with input voltage of 120 Vac (+10%, -15%), at 48 to 62 Hz.
T210 Series drives are rated for 208/240 Vac, single phase, 50-60 Hz input. The drive will
function with input voltage of 208 to 240 Vac (+10%, -15%), at 48 to 62 Hz.
T220 Series drives are rated for 208/240 Vac, three phase, 50-60 Hz input. The drive will
function with input voltage of 208 to 240 Vac (+10%, -15%), at 48 to 62 Hz.
T230 Series drives are rated for 400/480 Vac, three phase, 50-60 Hz input. The drive will
function with input voltage of 400 to 480 Vac (+10%, -15%), at 48 to 62 Hz.
NOTE: Parameter 01 - LINE VOLTAGE SELECTION must be programmed according to the
applied input voltage. See Section 15.0 - DESCRIPTION OF PARAMETERS.
DANGER
Page 12
8
7.2 INPUT FUSING AND DISCONNECT REQUIREMENTS
A circuit breaker or a disconnect switch with fuses must be provided in accordance with the
National Electric Code (NEC) and all local codes. Refer to the following tables for proper
fuse/circuit breaker ratings and wire sizes.
FUSE, CIRCUIT BREAKER, AND WIRE SIZES (for installation to UL and EN 60204-1)
NOTE:
• Applicable national and location electrical codes take precedence over recommendations
in these tables.
• Use UL Class CC fast-acting, current limiting type fuses. Select fuses with low 12T values,
rated at 200,000 AIC. Recommended fuses are Bussman KTK-R, JJN and JJS. Similar fuses
with equivalent ratings by other manufacturers may also be acceptable.
This product can cause a DC current in the protective conductor where a
residual current device (RCD) is used for pr otection in case of direct or indirect contact, only an
RCD of Type B is allowed on the supply side of this product. Otherwise another protective
measure shall be applied, such as separation from the environment by double or reinforced
insulation, or isolation from the supply system by a transformer. Observe the following when
using RCDs:
1. Only install the RCD between the supply mains and drive controller.
2. The RCD can be activated by:
- capacitive leakage currents between the cable screens during operation
(especially with long, screened motor cables)
- connecting several drives to the mains at the same time
- additional RFI filters
INPUT FUSE & CIRCUIT BREAKER RATINGS
120 Vac 1 phase 208/240 Vac 1 phase 208/240 Vac 3 phase 400/480 Vac 3 phase
T201 10A T211 10A
T202 15A T212 10A T222 10A T232 10A
T213 10A
T204 25A T214 15A T224 10A T234 10A
T205 35A T215 20A T225 12/10A T235 10A
T216 25/20A T226 15/12A T236 10A
T217 30/25A T227 20/15A T237 10A
T228 30/25A T238 15/12A
T229 45/40A T239 20/20A
T220 50/50A T230 30/25A
T221 80/75A T231 40/35A
WARNING
Page 13
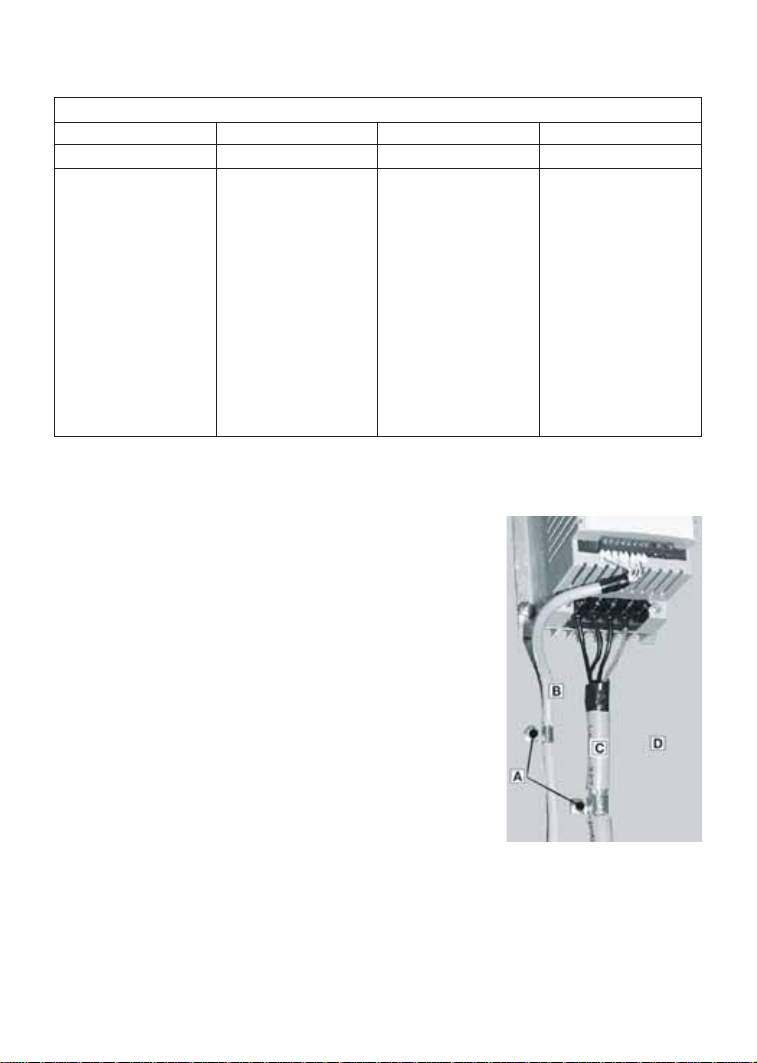
7.3 INSTALLATION ACCORDING TO EMC REQUIREMENTS
The SpinMaster™ Series can be installed to meet the European
standards Electromagnetic Compatibility (EMC) requirements.
These requirements govern the permissible electromagnetic
emissions and immunity, both radiated and conducted, of a
drive system.
The EMC requirements apply to the final installation in its
entirety, not to the individual components used. Because every
installation is different, the recommended installation should
follow these guidelines as a minimum. Additional equipment
(such as ferrite core absorbers on power conductors) or alternative wiring practices may be required to meet conformance
in some installations.
Filter: The input to the drive (or group of drives) must include a
filter to reduce the electrical noise reflected back to the AC Line.
The SpinMaster™ can be installed to meet these same standards
when used with an appropriately installed external line filter.
Installation: Shielded cable must be used for all control and power cables and exposed wiring
must be kept as short as possible. The figure to the right shows the control cable (B) and motor
cable (C) with the shield grounded with clamps (A) to a grounded, electrically conductive
mounting panel (D). The motor cable must be of a low capacitance specification:
core / core ≤ 75 pF/m, core/shield ≤ 150 pF/m
INPUT WIRE SIZE REQUIREMENTS
120 Vac 1 phase 208/240 Vac 1 phase 208/240 Vac 3 phase 400/480 Vac 3 phase
MODEL AWG mm2MODEL AWG mm2MODEL AWG mm2MODEL AWG mm
2
T201 14 2.5 T211 14 2.5
T202 14 2.5 T212 14 2.5 T222 14 2.5 T232 14 2.5
T213 14 2.5
T204 12 4.0 T214 14 2.5 T224 14 2.5 T234 14 2.5
T205 10 6.0 T215 14 2.5 T225 14 2.5 T235 14 2.5
T216 12 4.0 T226 14 2.5 T236 14 2.5
T217 10 6.0 T227 14 2.5 T237 14 2.5
T228 12 4.0 T238 14 2.5
T229 8 10.0 T239 12 4.0
T220 8 10.0 T230 10 6.0
T221 6 16.0 T231 8 10.0
9
Page 14
8.0 POWER WIRING
Hazard of electrical shock! Capacitors retain charge after power is removed.
Disconnect incoming power and wait until the voltage between terminals B+ and B- is 0 VDC
before servicing the drive.
Note drive input and output current ratings and check applicable electrical codes for required
wire type and size, grounding requirements, over-current protection, and incoming power
disconnect, before wiring the drive. Size conservatively to minimize voltage drop.
Input fusing and a power disconnect switch or contactor MUST be wired in series with
terminals L1 and L2/N (on single-phase input models), or terminals L1, L2, and L3 (on threephase input models). This disconnect must be used to power down the drive when servicing,
or when the drive is not to be operated for a long period of time, but should not be used to
start and stop the motor.
Repetitive cycling of a disconnect or input contactor (more than once every
two minutes) may cause damage to the drive.
8.1 INPUT AND OUTPUT WIRING
On single phase input models, wire the input power to terminals L1 and L2/N. On three phase
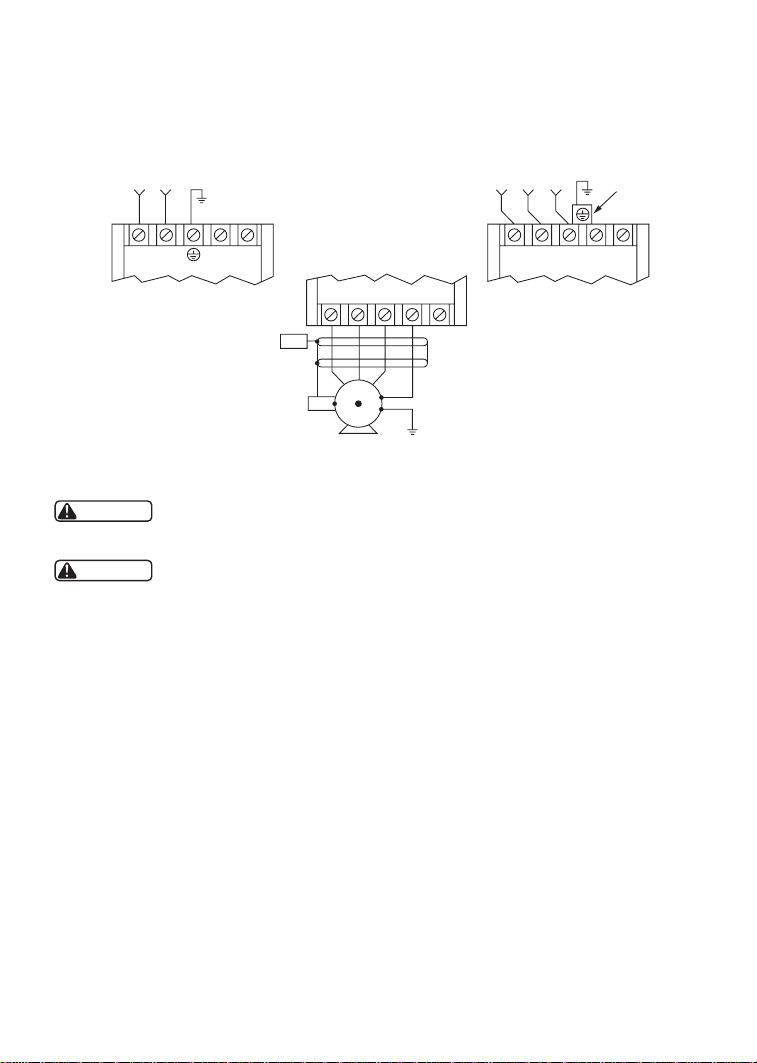
input models, wire the input power to terminals L1, L2, and L3. Refer to Section 9.0 SpinMaster™ POWER WIRING DIAGRAM.
All three power output wires, from terminals U, V, and W to the motor, must be kept tightly
bundled and run in a separate conduit away from all other power and control wiring.
It is not recommended to install contactors or disconnect switches between the drive and
motor. Operating such devices while the drive is running can potentially cause damage to the
drive’s power components. If such a device is required, it should only be operated when the
drive is in a STOP state. If there is potential for the device to be opened while the drive is
running, the drive must be programmed for COAST to stop (see Parameter 4 - STOP METHOD),
and an auxiliary contact on the device must be interlocked with the drive’s run circuit. This will
give the drive a stop command at the same time the device opens, and will not allow the drive
to start again until the device is closed.
10
DANGER
Page 15
11
Do not connect incoming AC power to output terminals U, V, or W, or
terminals B+, B- ! Severe damage to the drive will result.
Leakage current may exceed 3.5mA AC. Minimum size of the protective earth
conductor shall comply with local safety regulations for high leakage current equipment.
Strip off 0.25 inches (6mm) for the .25 - 5 HP, .35 inches (9mm) for the 7.5 - 10 HP and .5
inches (13mm) for the 15 HP of insulation for input power, output power, and DC Bus wiring.
The input power, output power, and DC Bus terminals must be tightened to a torque of 4.5
lb-in (0.5 Nm) for the .25 - 5 HP, 10 lb-in (1.2 Nm) for the 7.5 - 10 HP and 18 lb-in (2.0 Nm)
for the 15 HP.
NOTE:
• WIRE AND GROUND IN ACCORDANCE WITH NEC OR CEC, AND ALL APPLICABLE LOCAL
CODES.
• Motor wires MUST be run in a separate steel conduit away from control wiring and
incoming AC power wiring.
• Do not install contactors between the drive and the motor without consulting REGAL
BELOIT CORPORATION for more information. Failur e to do so may r esult in drive damage.
• Use only UL and CSA listed and approved wire.
• Minimum wire voltage rating is 300 V for 120, 208, and 240 Vac systems, and 600 V for
400 and 480 Vac systems.
• Wire gauge must be based on a minimum of 125% of the rated input/output current of
the drive, and a minimum 75° C insulation rating. Use copper wire only.
9.0 SpinMaster™ POWER WIRING DIAGRAM
WARNING
WARNING
(SINGLE-PHASE MODELS ONLY)
INPUT
INPUT AC
VOLTAGE
L1 B- B+
L2/N
PE
OUTPUT (ALL MODELS)
PES
PES
3 PHASE
AC MOTOR
(THREE-PHASE MODELS ONLY)
PEWVU
PE
INPUT
INPUT AC
VOLTAGE
L1 L2 L3 B- B+
PE Lug on
Heatsink
Page 16
10.0 CONTROL WIRING
10.1 CONTROL WIRING VS. POWER WIRING
External control wiring MUST be run in a separate conduit away from all other input and
output power wiring. If control wiring is not kept separate from power wiring, electrical noise
may be generated on the control wiring that will cause erratic drive behavior. Use twisted
wires or shielded cable grounded at the drive chassis ONLY. Recommended control wire is
Belden 8760 (2-wire) or 8770 (3-wire), or equivalent.
NOTE: Control terminals provide basic isolation (insulation per EN61800-5A. Protection
against contact can only be assured by additional measures e.g. supplemental insulation.
Strip off 0.20 to 0.25 inches (5 to 6 mm) of insulation for control wiring, and torque the control terminals to 2 lb-in (0.2 Nm). Be careful not to overtorque the control terminals, as this will
cause damage to the terminal strip. This is not covered under warranty and can only be
repaired by replacing the control board.
10.2 TB-2: CIRCUIT COMMON
The TB-2 terminal is used as circuit common for the analog speed reference inputs. If
necessary TB-2 may be connected to chassis ground.
10.3 SURGE SUPPRESSION ON RELAYS
Current and voltage surges and spikes in the coils of contactors, relays, solenoids, etc, near or
connected to the drive, can cause erratic drive operation. Therefore, a snubber circuit should
be used on coils associated with the drive. For AC coils, snubbers should consist of a resistor
and a capacitor in series across the coil. For DC coils, a free-wheeling or flyback diode should
be placed across the coil. Snubbers are typically available fr om the manufacturer of the device.
10.4 START/STOP CONTROL
There are various control schemes that allow for 2-wire and 3-wire Start/Stop circuits. Refer to
the wiring diagrams in Section 11.0 - SpinMaster™ CONTROL WIRING DIAGRAMS.
10.5 SPEED REFERENCE SIGNALS
The drive allows for three analog speed reference inputs:
SPEED POT Connect the wiper of a speed pot to terminal TB-5, and connect the high and
low end leads to terminals TB-6 and TB-2, respectively. The speed pot can be
2.5kΩ up to 10kΩ.
0-10 VDC Wire the positive to terminal TB-5 and the negative to terminal TB-2. TB-5 input
impedance is 120kΩ.
4-20 mA Wire the positive to terminal TB-25 and the negative to terminal TB-2. TB-25
input impedance is 250Ω.
12
Page 17
13
10.6 SPEED REFERENCE SELECTION
If an analog speed reference input is used to control the drive speed, terminal TB-13A, 13B,
or 13E (Parameter 10, 11, or 12) may be programmed as the input select for the desired
analog input signal. When that TB-13 terminal is then closed to TB-11, the drive will follow the
selected analog speed reference input.
If an analog speed reference input is not selected on the terminal strip using TB-13A, 13B, or
13E, speed control will default to STANDARD mode, which is governed by the setting of
Parameter 05 - STANDARD SPEED SOURCE. The STANDARD SPEED SOURCE can be the L and
M buttons on the front of the drive, PRESET SPEED #1(Parameter 31), a 0-10 VDC signal, or a
4-20 mA signal.
0-10 VDC and 4-20 mA INPUT SIGNALS
TB-13A, TB-13B, and TB-13E can all be programmed to select a 0-10 VDC or 4-20 mA analog
speed reference input.
PRESET SPEEDS
TB-13A can be programmed to select PRESET SPEED #1 (04), TB-13B to select PRESET SPEED
#2 (04), and TB-13E to select PRESET SPEED #3 (04). There are a total of seven preset speeds,
which are activated by different combinations of contact closures between TB-13A, 13B, 13E
and TB-11. Refer to Parameters 31-37 in Section 15.0 - DESCRIPTION OF PARAMETERS.
JOG
TB-13B can be programmed to select either JOG FORWARD (07) or JOG REVERSE (08). The
Jog speed is set by PRESET SPEED #2 (Parameter 32). Close TB-13B to TB-11 to JOG, and open
the contact to STOP.
When operating in JOG mode, the STOP signal and the AUXILIARY STOP
function (see Parameters 10-12), or the STOP key on the optional remote keypad WILL NOT
stop the drive. To stop the drive, remove the JOG command.
JOG REVERSE will operate the drive in reverse rotation even if ROTATION
DIRECTION (Parameter 17) is set to FORWARD ONLY.
NOTE: If the drive is commanded to JOG while running, the drive will enter JOG mode and
run at PRESET SPEED #2. When the JOG command is removed, the drive will STOP.
MOTOR OPERATED POT (MOP) / FLOATING POINT CONTROL
TB-13B and TB-13E are used for this function, which controls the drive speed using contacts
wired to the terminal strip. Program TB-13B for DECREASE FREQ (05), and pr ogram TB-13E for
INCREASE FREQ (05). Closing TB-13B to TB-11 will cause the speed setpoint to decrease until
the contact is opened. Closing TB-13E to TB-11 will cause the speed setpoint to increase
until the contact is opened. The INCREASE FREQ function will only operate while the drive is running.
WARNING
WARNING
Page 18
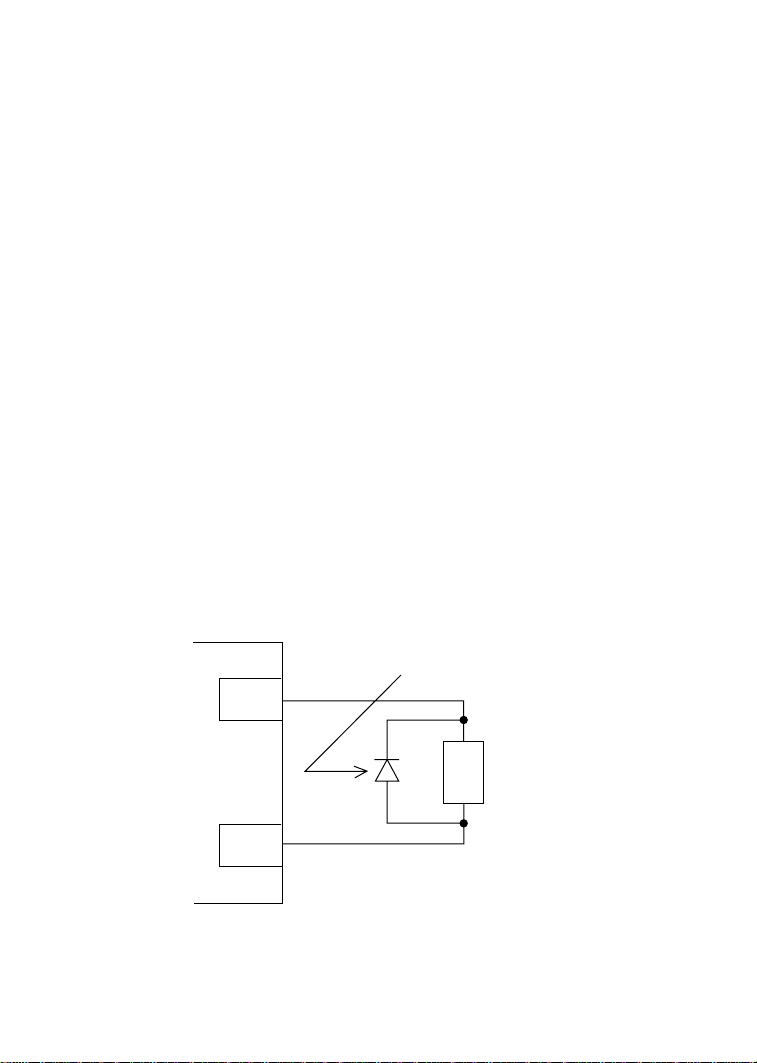
DIODE SNUBBER
(1N4148 or Equivalent)
RELAY COIL
TB-2
TB-13E
SPINMASTER
TERMINAL STRIP
NOTE: If TB-13A, TB-13B, and TB-13E are all pr ogrammed to select speed r efer ences, and two
or three of the terminals are closed to TB-11, the higher terminal has priority and will override
the others. For example, if TB-13A is programmed to select 0-10 VDC, and TB-13E is
programmed to select PRESET SPEED #3, closing both terminals to TB-11 will cause the drive
to respond to PRESET SPEED #3, because TB-13E overrides TB-13A.
The exception to this is the MOP function, which requires the use of TB-13B and TB-13E. This
leaves TB-13A to be used for some other function. If TB-13A is programmed for a speed
reference, and TB-13A is closed to TB-11, TB-13A will override the MOP function.
10.7 DRIVE STATUS DIGITAL OUTPUTS
There is one Form A relay at terminals TB-16 and TB-17. Relay contacts ar e rated 3 amps at 250
Vac.
Terminal TB-13E can also be configured as a digital output. This output circuit is a currentsourcing type rated at 12 VDC and 50 mA maximum.
The Form A relay and digital output can be programmed to indicate any of the following:
RUN, FAULT, INVERSE FAULT, FAULT LOCKOUT, AT SPEED, ABOVE PRESET SPEED #3, CURRENT
LIMIT, AUTO SPEED MODE, and REVERSE. Refer to Parameters 06 and 12 in Section 15.0 DESCRIPTION OF PARAMETERS.
The diagram below illustrates how TB-13E, when configured as a digital output, can be used
to drive an external relay:
14
Page 19
15
11.0 SpinMaster™ CONTROL WIRING DIAGRAMS
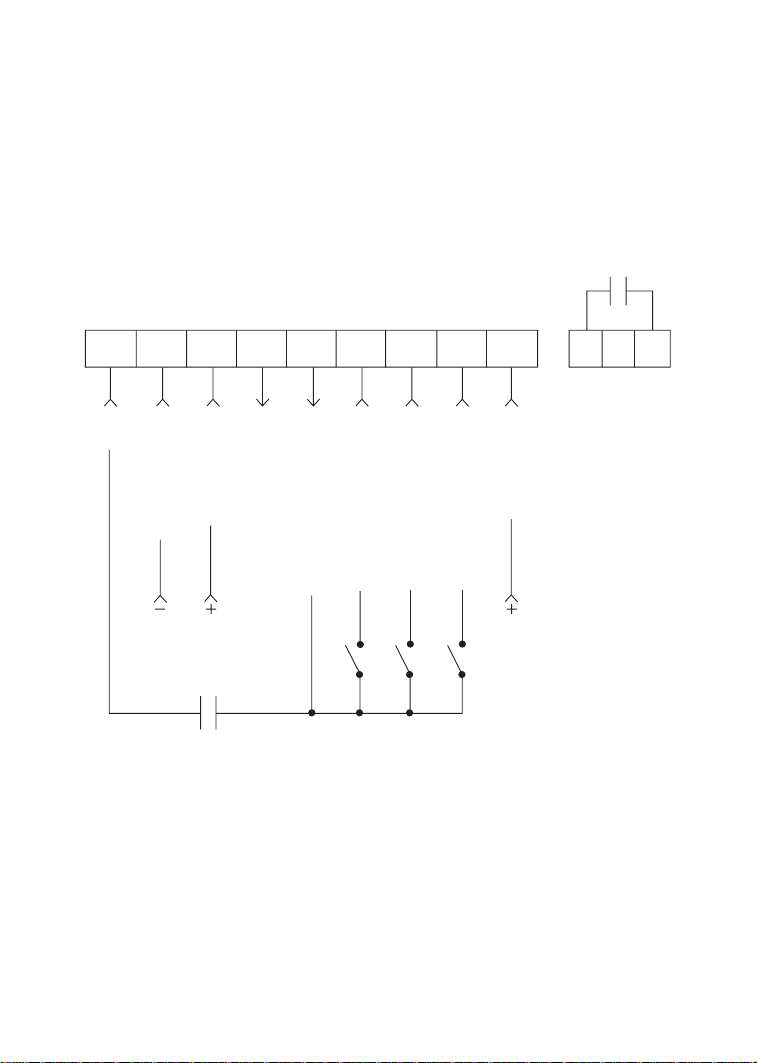
11.1 SpinMaster™ TERMINAL STRIP
Shown below is the control terminal strip, along with a brief description of the function of each
terminal. The following wiring diagram examples provide a quick reference to wire the drive
for the most common configurations.
NOTE:
• The function of terminals TB-13A, TB-13B, TB-13E and the Form A r elay at terminals 16 and
17 are dependent on the programming of certain parameters. Refer to Section 15.0 DESCRIPTION OF PARAMETERS.
• The digital inputs (terminals 1, 13A, 13B, and 13E) are active-high. They can be
activated using terminal 11 (which is +12 VDC) as shown in the following diagrams, or by
using an external voltage source with a range of +12 VDC to +28 VDC (± 10%).
1 2 5 6 11 13A 13B 13E 25
16 17
MAINTAINED
RUN/STOP
CONTACT
FORM A
RELAY
RUN
SIGNAL COMMON
0-10 VDC INPUT
SPEED POT POWER SUPPLY
DIGITAL INPUT REFERENCE
TB-13A FUNCTION SELECT
TB-13B FUNCTION SELECT
TB-13E FUNCTION SELECT
4-20 mA INPUT
Page 20
16
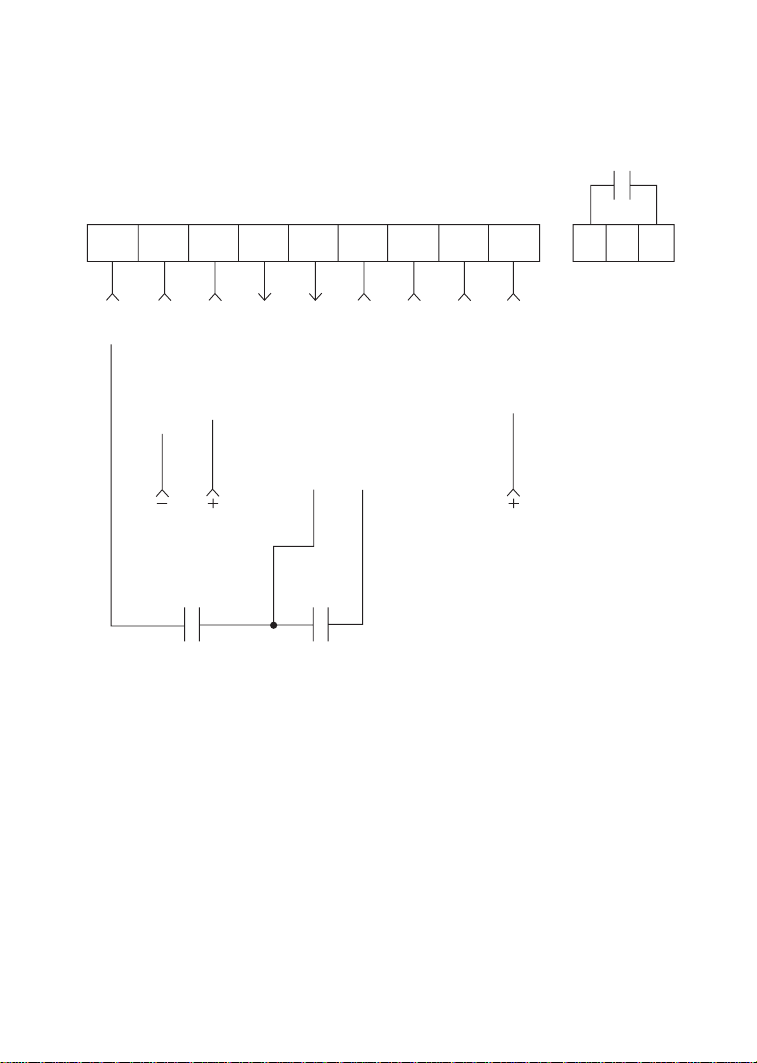
11.2 TWO-WIRE START/STOP CONTROL
NOTE:
• Close TB-1 to TB-11 to RUN and open to STOP. TB-1 functions as a RUN input for two-wire
start/stop circuits, and a STOP input for three-wire start/stop circuits. Refer to Section 11.3.
• If reverse direction is required, set ROTATION (Parameter 17) to FORWARD AND REVERSE
(02), and program TB-13A (Parameter 10) to RUN REVERSE (06). Close TB-13A to TB-11 to
RUN in the reverse direction, and open to STOP.
• For 0-10 VDC or 4-20 mA speed control, set STANDARD SPEED SOURCE (Parameter 05) to
0-10 VDC (03) or 4-20 mA (04).
1 2 5 6 11 13A 13B 13E 25
16 17
MAINTAINED
RUN/STOP CONTACT
(FORWARD)
MAINTAINED
RUN/STOP CONTACT
(REVERSE)
FORM A
RELAY
RUN
SIGNAL COMMON
0-10 VDC INPUT
SPEED POT POWER SUPPLY
DIGITAL INPUT REFERENCE
TB-13A FUNCTION SELECT
(RUN REVERSE)
TB-13B FUNCTION SELECT
TB-13E FUNCTION SELECT
4-20 mA INPUT
Page 21
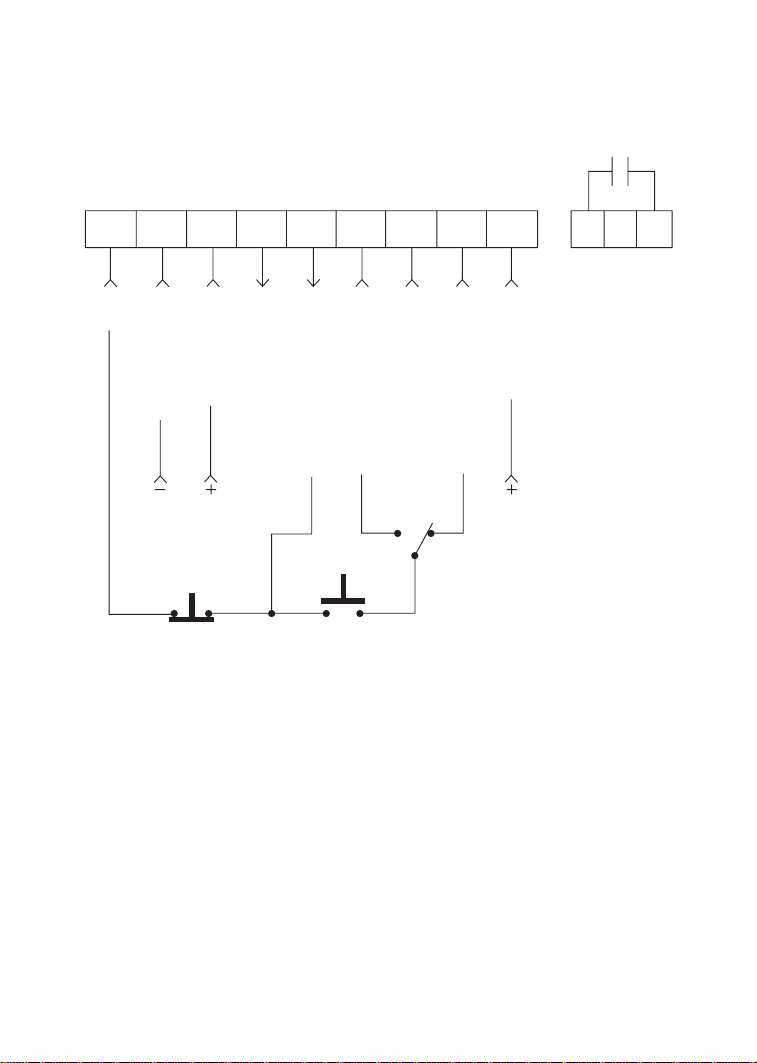
17
11.3 THREE-WIRE START/STOP CONTROL
NOTE:
• Program TB-13E (Parameter 12) for START FORWARD (06).
• If reverse direction is required, set ROTATION (Parameter 17) to FORWARD AND REVERSE
(02), and program TB-13A (Parameter 10) for START REVERSE (07).
• Momentarily close TB-13E to TB-11 to START in the forward direction, or close TB-13A to
TB-11 to START in the reverse direction. Momentarily open TB-1 to TB-11 to STOP the drive.
• For 0-10 VDC or 4-20 mA speed control, set STANDARDSPEED SOURCE (Parameter 05) to
0-10 VDC (03) or 4-20 mA (04).
1 2 5 6 11 13A 13B 13E 25
16 17
MOMENTARY
STOP CONTACT
MOMENTARY
START CONTACT
REV FWD
FORM A
RELAY
STOP
SIGNAL COMMON
0-10 VDC INPUT
SPEED POT POWER SUPPLY
DIGITAL INPUT REFERENCE
TB-13A FUNCTION SELECT
(START REVERSE)
TB-13B FUNCTION SELECT
TB-13E FUNCTION SELECT
(START FORWARD)
4-20 mA INPUT
Page 22
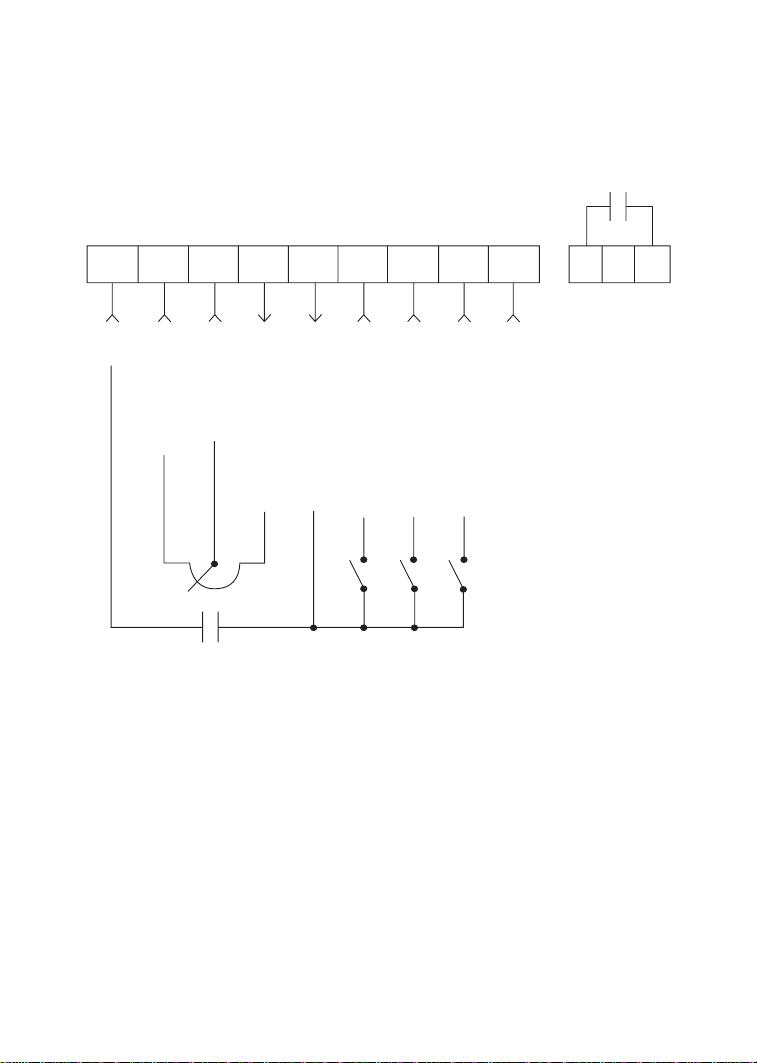
18
11.4 PRESET SPEEDS AND SPEED POT
(WITH TWO-WIRE START/STOP CONTROL)
NOTE:
• For preset speed control, all or some of the TB-13 terminals must be programmed as
preset speed selects. If only two or three preset speeds are required, only two of the
TB-13 terminals must be used. Refer to the table in the description of Parameters 31-37 in
Section 15.0.
• Program the PRESET SPEEDS (Parameters 31-37) to the desired values.
• If speed pot control is desired when none of the preset speeds are selected (all preset
speed selects are open to TB-11), set STANDARD SPEEDSOURCE (Parameter 05) to 0-10
VDC (03).
1 2 5 6 11 13A 13B 13E 25
16 17
MAINTAINED
RUN/STOP
CONTACT
SPEED
POT
FORM A
RELAY
RUN
SIGNAL COMMON
0-10 VDC INPUT
SPEED POT POWER SUPPLY
DIGITAL INPUT REFERENCE
TB-13A FUNCTION SELECT
(PRESET SPEED #1)
TB-13B FUNCTION SELECT
(PRESET SPEED #2)
TB-13E FUNCTION SELECT
(PRESET SPEED #3)
Page 23
19
12.0 INITIAL POWER UP AND MOTOR ROTATION
Hazard of electrical shock! Wait three minutes after disconnecting incoming
power before servicing drive. Capacitors retain charge after power is removed.
DO NOT connect incoming AC power to output terminals U, V, and W or
terminals B+, B-! Severe damage to the drive will result. Do not continuously cycle input power
to the drive more than once every two minutes. Damage to the drive will result.
Severe damage to the drive can result if it is operated after a long period of
storage or inactivity without reforming the DC bus capacitors!
For information on DC bus capacitor reforming, please see Section 6.1 - INSTALLATION AFTER
A LONGER PERIOD OF STORAGE.
Before attempting to operate the drive, motor, and driven equipment, be sure all procedures
pertaining to installation and wiring have been properly followed.
Disconnect the driven load from the motor. Verify that the drive input terminals (L1, L2/N, or
L1, L2, and L3) are wired to the proper input voltage per the nameplate rating of the drive.
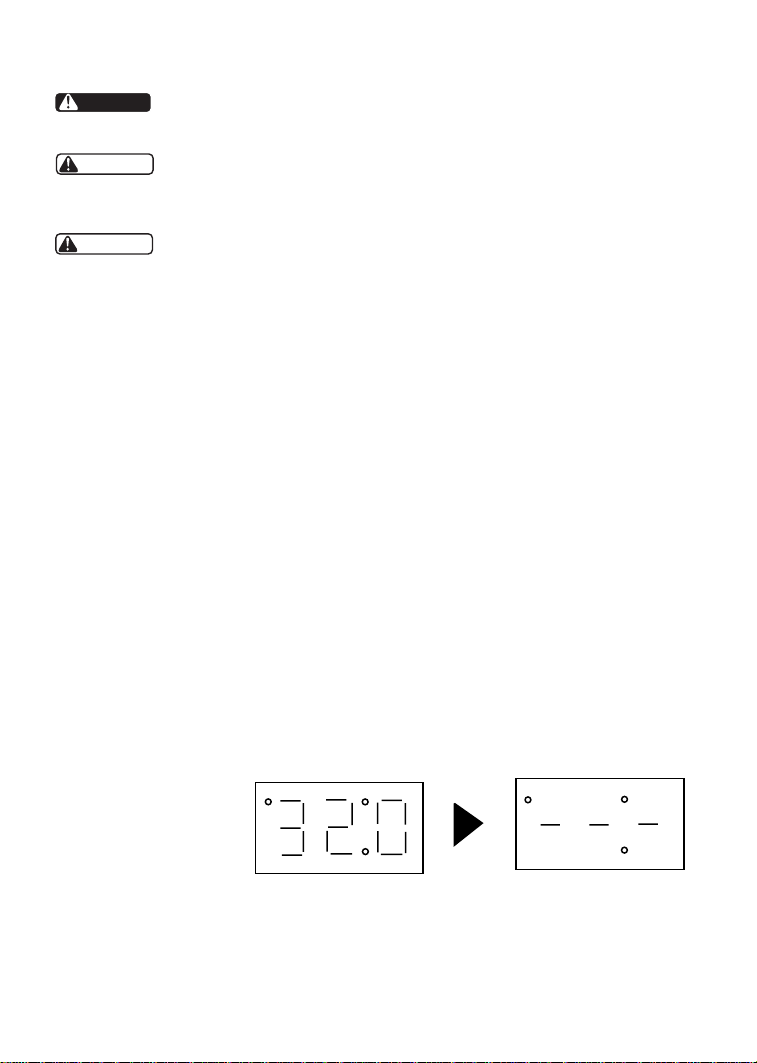
Energize the incoming power line. The LED display will flash a three digit number (320 in the
example below) that identifies the parameter version contained in the drive. The display should
then read “- - -”, which indicates that the drive is in a STOP condition. This is shown below:
Apply input power
Display flashes parameter
version (300-399)
Display then reads “- - -”
WARNING
WARNING
DANGER
Page 24
20
Follow the procedure below to check the motor rotation. This procedure assumes that the
drive has been powered up for the first time, and that none of the parameters have been
changed.
1. Use the M button to decrease the speed setpoint to 00.0 Hz. The left decimal point will
illuminate as the speed setpoint is decreased. If the M button is held down, the speed
setpoint will decrease by tenths of Hz until the next whole Hz is reached, and then it will
decrease by one Hz increments. Otherwise, each push of the M button will decrease the
speed setpoint by a tenth of a Hz.
Once 00.0 Hz is reached, the display will toggle between “00.0” and “- - -”, which
indicates that the drive is in a STOP condition with a speed setpoint of 00.0 Hz.
2. Give the drive a START command. This can be done using one of several wiring methods
described in Section 11.0 - SpinMaster™ CONTROL WIRING DIAGRAMS. Once the START
command is issued, the display will read “00.0”, indicating that the drive is in a RUN
condition with a speed setpoint of 00.0 Hz.
3. Use the L button to increase the speed setpoint until the motor starts to rotate. The left
decimal point will light as the speed setpoint is increased. If the L button is held down,
the speed setpoint will increase by tenths of Hz until the next whole Hz is reached, and
then it will increase by one Hz increments. Otherwise, each push of the button will
increase the speed setpoint by a tenth of a Hz.
4. If the motor is rotating in the wrong direction, give the drive a STOP command and
remove power from the drive. W ait thr ee minutes for the bus capacitors to discharge, and
swap any two of the motor wires connected to U, V, and W.
NOTE: The drive is phase insensitive with respect to incoming line voltage. This means that
the drive will operate with any phase sequence of the incoming three phase voltage.
Therefore, to change the motor rotation, the phases must be swapped at the drive output
terminals or at the motor.
Page 25
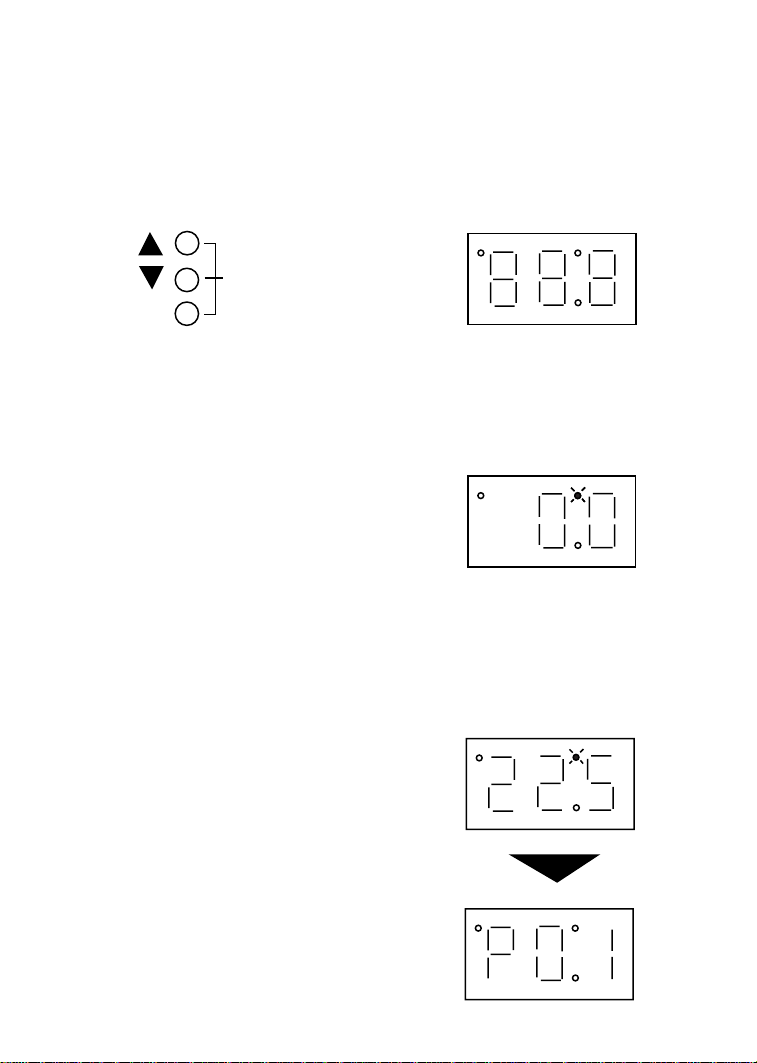
21
13.0 PROGRAMMING THE SpinMaster™ DRIVE
The drive may be programmed by one of two methods: using the three buttons and 3-digit
LED display on the front of the display, or programming the Electronic Programming Module
(EPM) using the optional EPM Programmer. This section describes programming the drive
using the buttons and display, which are shown below:
To enter the PROGRAM mode to access the parameters, press the Mode button. This will
activate the PASSWORD prompt (if the password has not been disabled). The display will read
“00” and the upper right-hand decimal point will be blinking, as shown below:
Press Mode
Display reads “00”
Upper right decimal point blinks
Use the L and M buttons to scroll to the password value (the factory default password is
“225”) and press the Mode button. Once the correct password value is entered, the display
will read “P01”, which indicates that the PROGRAM mode has been accessed at the beginning
of the parameter menu (P01 is the first parameter). This is shown below:
Use L and M to scroll to the
password value
Press Mode to enter password
Parameter menus is accessed at the
first parameter
BUTTONS
Mode
DISPLAY
Page 26
22
NOTE: If the display flashes “Er”, the password was incorrect, and the process to enter the
password must be repeated.
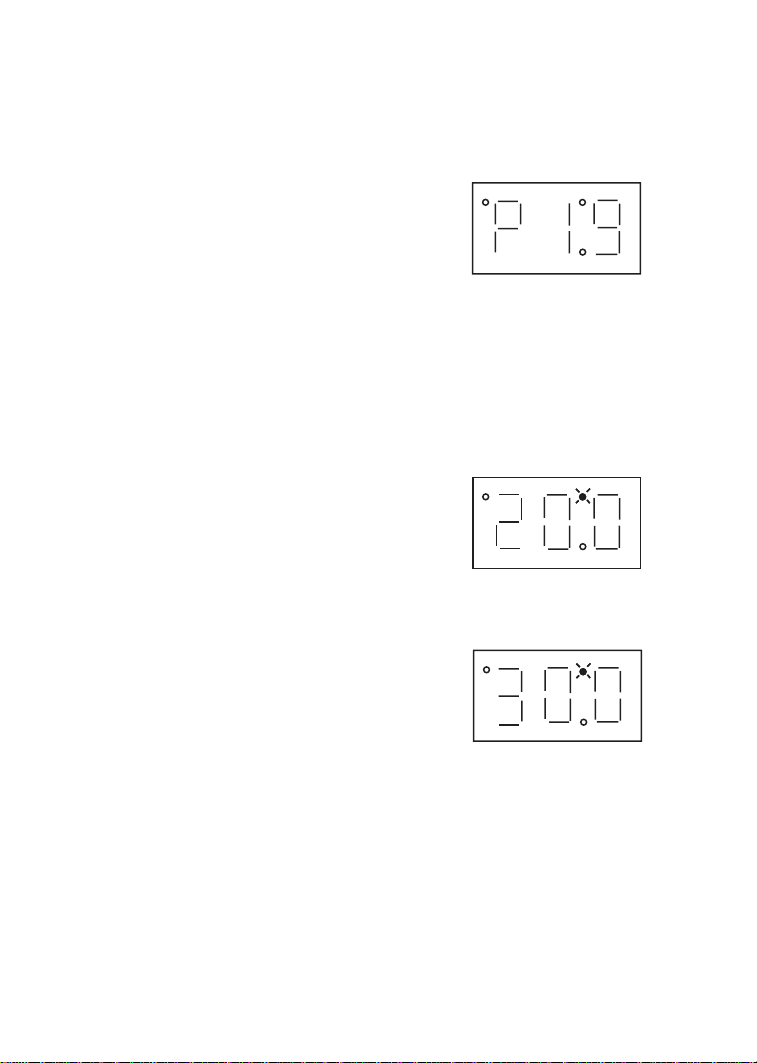
Use the L and M buttons to scroll to the desired parameter number. In the example below,
Parameter 19 is being displayed, which is the ACCELERATION TIME of the drive:
Use L and M to scroll to the desired
parameter number (the example is
Parameter 19 - ACCELERATION
TIME)
Once the desired parameter number is found, press the Mode button to display the present
parameter setting. The upper right-hand decimal point will begin blinking, indicating that the
present parameter setting is being displayed, and that it can be changed by using the L and
M buttons.
Press Mode to display present
parameter setting (example setting
is 20.0)
Upper right decimal point blinks
Use L and M to change setting
(example setting changed to 30.0)
Press Mode to store new setting
Pressing the Mode will store the new setting and also exit the PROGRAM mode. To
change another parameter, press the Mode key again to re-enter the PROGRAM mode (the
parameter menu will be accessed at the parameter that was last viewed or changed before
exiting). If the Mode key is pressed within two minutes of exiting the PROGRAM mode, the
password is not required access the parameters. After two minutes, the password must be
entered in order to access the parameters again.
Page 27
13.1 SETTING VALUES IN TENTHS OF UNITS ABOVE 100
Parameter settings and the keypad speed command can always be adjusted in tenths of unit
increments from 0.0 to 99.9. Above 100 however, values can be set in whole units or tenths
of units, depending on the setting of Parameter 16 - UNITS EDITING.
If Parameter 16 - UNITS EDITING is set to WHOLE UNITS (02), parameter values and the
keypad speed command can only be adjusted by whole unit increments above 100. For example, Parameter 19 - ACCELERATION TIME could not be set to 243.7 seconds. It could only be
set to 243 or 244 seconds. Likewise, the keypad speed command (set using the L and M buttons) could not be set to 113.4 Hz. It could only be set to 113 or 114 Hz.
If, however, Parameter 16 - UNITS EDITING is set to TENTHS OF UNITS (01), parameter values
and the keypad speed command can be adjusted in tenths of unit increments up to a value
of 1000 (above 1000, whole unit increments only). Each push of the L or M button will
adjust the value by one tenth of a unit. If the L or M button is pressed and held, the value
will increment by tenths of units until the next whole unit is reached, and then the value will
increment by whole units.
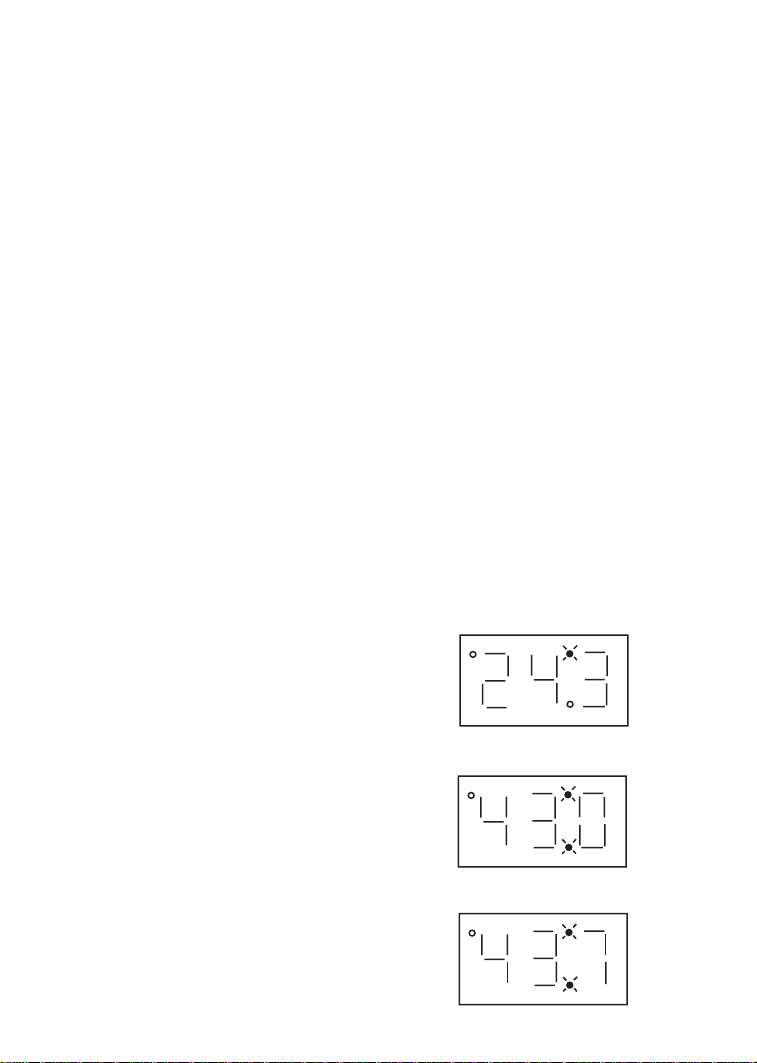
When a value above 100 is being adjusted by tenths of units, the value is shifted to the left by
one digit so that the tenths portion of the value can be displayed. This results in the first digit
(reading from left to right) of the value disappearing from the display. Also, the lower decimal
point will blink to indicate that the actual value is above 100. Once the value is no longer
being adjusted, the value will shift back to the right and the tenths portion of the value will
disappear.
In the example below, Parameter 19 - ACCELERATION TIME is presently set to 243.0 seconds,
and is being increased to 243.7 seconds.
Go to Parameter 19 and press Mode
to see present setting (“243” seconds)
Upper right decimal point blinks
Press L button to see tenths portion
Value shifts to the left (“2” disappears)
Upper right decimal point and lower
decimal point blink
Press L button to scroll up to “43.7”
Press Mode to store new value
23
Page 28
24
13.2 ELECTRONIC PROGRAMMING MODULE (EPM)
Every SpinMaster™ drive has an Electronic Programming Module (EPM) installed on the main
control board. The EPM stores the user’s parameter settings and special OEM default settings
(if programmed). The EPM is removable, allowing it to be installed in another drive for quick
set-up. For example, if a drive is being replaced with a new one, the EPM can be taken out of
the first drive and installed in the new drive. Downtime is minimized because the new drive
does not require programming - it is ready to run when the EPM is installed.
The SpinMaster™ drive contains two or three sets of parameter values, depending on whether
the drive has been programmed with optional OEM default settings. The first set of values is
the factory default settings, which are permanently stored on the main control board and
cannot be changed. The second set of values is the user settings, which are stored in the EPM.
When the drive leaves the factory, the user settings ar e the same as the factory default settings,
but the user settings can be changed to configure the drive for a particular application. The
optional third set of values is the OEM default settings, which are also stored in the EPM.
OEM default settings are typically used in cases where many drives are used for the same
application, which requires that all of the drives have the same parameter settings. The OEM
default settings cannot be changed without the optional EPM Programmer. The drive can be
programmed to operate according to the user settings or the OEM default settings (see
Parameter 48 in Section 15.0).
NOTE: The drive will not operate without the EPM installed, The drive will display “F1” if the
EPM is missing or damaged.
Do not remove the EPM while power is applied to the drive. Damage to the
EPM and/or drive may result.
An EPM Programmer is available as an option from REGAL BELOIT CORPORATION, which has
the ability to quickly and easily program many SpinMaster™ drives for the same configuration.
Once a “master” EPM is programmed with the desired parameter settings, the EPM
Programmer can copy those setting to other EPMs, allowing many drives to be configured very
quickly. Please consult the EPM Programmer Instruction Manual or contact the factory for mor e
information.
If the OEM settings in the EPM become corrupted, the drive will operate normally, until an
attempt is made to perform a RESET OEM using Parameter 48 - PROGRAM SELECTION. The
drive will then flash “GF” to indicate that the OEM settings are no longer valid. This will requir e
that the EPM be re-programmed using the optional EPM Programmer.
If the OEM settings and the user settings are both corrupted, the drive will display “GF”
immediately and the drive will require a RESET 60 or RESET 50 using Parameter 48 - PROGRAM
SELECTION. Once the RESET is performed, the parameters can then be programmed
individually to match the OEM default settings. This will allow the drive to operate as if it were
in OEM mode, even though it is actually in USER mode. Refer to Parameter 48 in Section 15.0
- DESCRIPTION OF PARAMETERS.
NOTE: The drive will also display “GF” if a RESET OEM or OPERATE WITH OEM SETTINGS is
attempted when the drive is not equipped with the OEM default option.
WARNING
Page 29
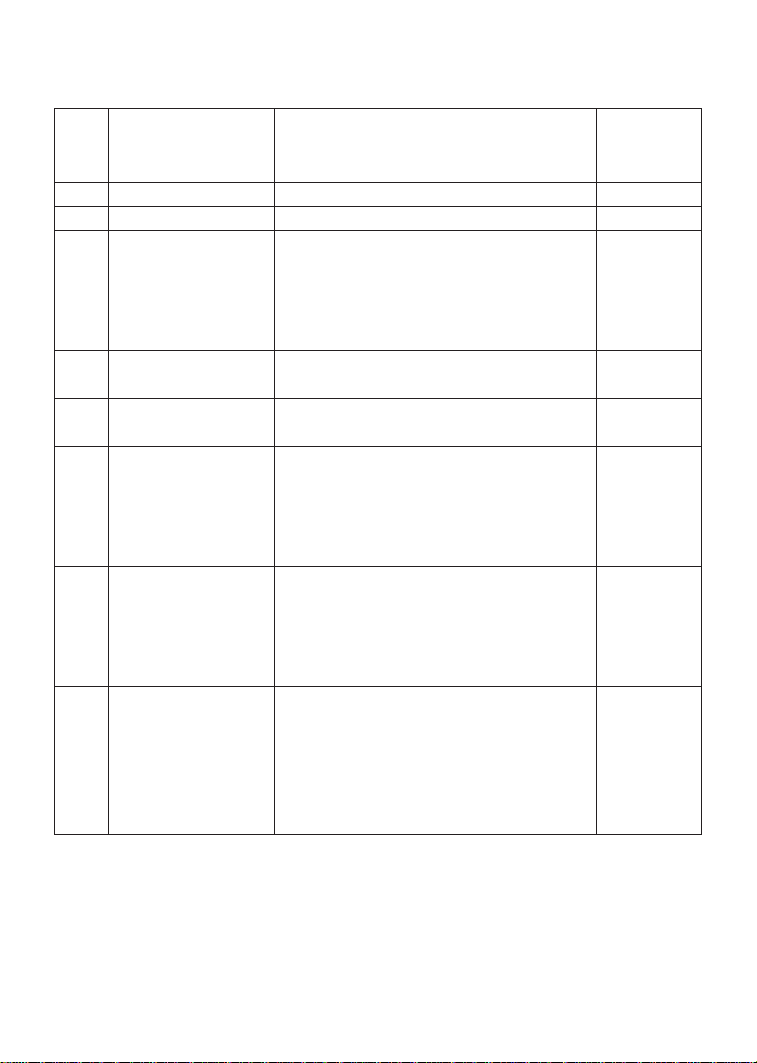
25
14.0 PARAMETER MENU
FACTORY
NO. PARAMETER NAME RANGE OF ADJUSTMENT DEFAULT
(NOTE 1)
01 LINE VOLTAGE HIGH (01), LOW (02) HIGH (01)
02 CARRIER FREQUENCY 4kHz (01), 6kHz (02), 8kHz (03), 10 kHz (04) 6 kHz (02)
03 START METHOD NORMAL (01), START ON POWER UP (02), NORMAL (01)
START WITH DC BRAKE (03),
AUTO RESTART WITH DC BRAKE (04),
FLYING RESTART 1 (05,) FLYING RESTART 2 (06),
FLYING RESTART 3 (07)
04 STOP METHOD COAST (01), COAST WITH DC BRAKE (02), COAST (01)
RAMP (03), RAMP WITH DC BRAKE (04)
05 STANDARD SPEED KEYPAD (01), PRESET #1 (02), KEYPAD (01)
SOURCE 0-10 VDC (03), 4-20 mA (04)
06 RELAY OUTPUT NONE (01), RUN (02) ,FAULT (03), NONE (01)
INVERSE FAULT (04), FAULT LOCKOUT (05),
AT SET SPEED (06), ABOVE PRESET #3 (07),
CURRENT LIMIT (08), AUTO SPEED (09),
REVERSE (10)
10 TB-13A FUNCTION NONE (01), 0-10 VDC(02), 4-20mA (03), NONE (01)
SELECT PRESET SPEED #1 (04), START FORWARD (05),
RUN REVERSE (06), START REVERSE (07),
EXTERNAL FAULT (08), INVERSE EXT FAULT (09),
AUXILIARY STOP (10), ACCEL/DECEL #2 (11)
11 TB-13B FUNCTION NONE (01), 0-10 VDC (02), 4-20mA (03), NONE (01)
SELECT PRESET SPEED #2 (04), DECREASE FREQ (05),
START FORWARD (06), JOG FORWARD (07),
JOG REVERSE (08), EXTERNAL FAULT (09),
INVERSE EXT FAULT (10), AUXILIARY STOP (11),
ACCEL/DECEL #2 (12), REMOTE KEYPAD (13)
NOTE 1: Factory defaults are shown for a 60 Hz base frequency. See Parameter 48 for 50
Hz base frequency.
Page 30
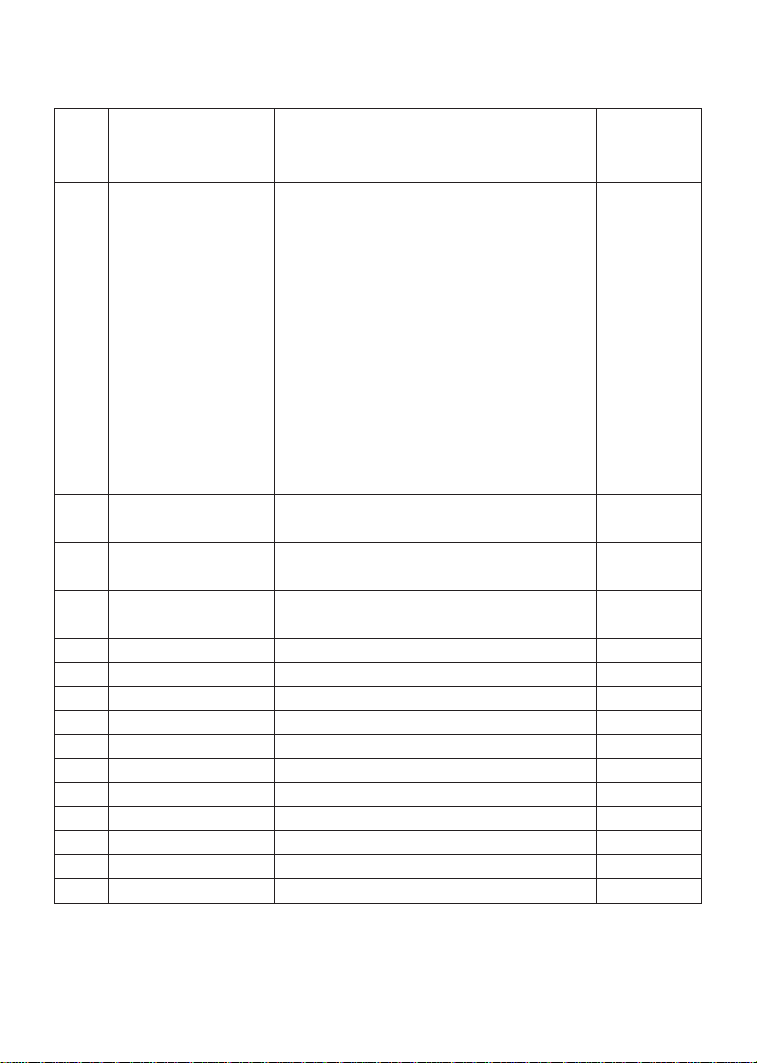
26
FACTORY
NO. PARAMETER NAME RANGE OF ADJUSTMENT DEFAULT
(NOTE 1)
12 TB-13E INPUT NONE (01), 0-10 VDC (02), 4-20mA (03), NONE (01)
FUNCTION SELECT PRESET SPEED #3 (04), INCREASE FREQ (05),
START FORWARD (06), EXTERNAL FAULT (07),
INVERSE EXT FAULT (08), AUXILIARY STOP (09),
ACCEL/DECEL #2 (10).
TB-13E OUTPUT RUN (11), FAULT (12), INVERSE FAULT (13),
SELECT FUNCTION FAULT LOCKOUT (14), AT SET SPEED (15),
ABOVE PRESET #3 (16), CURRENT LIMIT (17),
AUTO SPEED (18), REVERSE (19),
DYNAMIC BRAKING (20),
OTHER FUNCTIONS REMOTE KEYPAD (21)
14 CONTROL TERMINAL STRIP ONLY (01), TERMINAL STRIP
REMOTE KEYPAD ONLY (02), ONLY (01)
16 UNITS EDITING TENTHS OF UNITS (01), WHOLE
WHOLE UNITS (02) UNITS (02)
17 ROTATION FORWARD ONLY (01), FORWARD
FORWARD AND REVERSE (02) ONLY (01)
19 ACCELERATION TIME 0.1 - 3600.0 SEC 20.0 SEC
20 DECELERATION TIME 0.1 - 3600.0 SEC 20.0 SEC
21 DC BRAKE TIME 0.0 - 3600.0 SEC 0.0 SEC
22 DC BRAKE VOLTAGE 0.0 - 30.0 % 0.0 %
23 MINIMUM FREQUENCY 0.0 - MAXIMUM FREQUENCY 0.0 Hz
24 MAXIMUM FREQUENCY MINIMUM FREQ - 240 Hz 60.0 Hz
25 CURRENT LIMIT 30 - 180 % 180 %
26 MOTOR OVERLOAD 30 - 100 % 100 %
27 BASE FREQUENCY 25.0 - 500.0 Hz 60.0 Hz
28 FIXED BOOST 0.0 - 30.0% 1.0%
29 ACCEL BOOST 0.0 - 20.0% 0.0%
PARAMETER MENU (cont)
NOTE 1: Factory defaults are shown for a 60 Hz base frequency. See Parameter 48 for 50
Hz base frequency.
Page 31
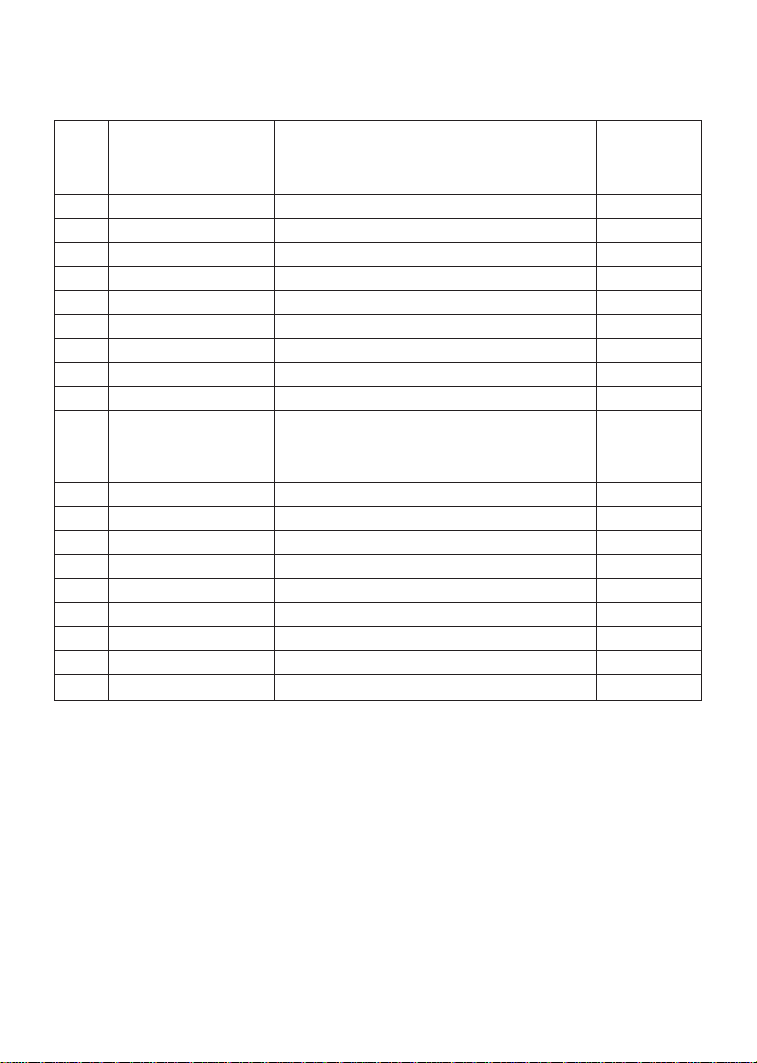
27
FACTORY
NO. PARAMETER NAME RANGE OF ADJUSTMENT DEFAULT
(NOTE 1)
30 SLIP COMPENSATION 0.0 - 5.0 % 0.0 %
31-37 PRESET SPEEDS 0.0 - MAXIMUM FREQUENCY 0.0 Hz
38 SKIP BANDWIDTH 0.0 - 10.0 Hz 0.0 Hz
39 SPEED SCALING 0.0 - 6500.0 0.0
42 ACCEL / DECEL #2 0.1 - 3600.0 SEC 20.0 SEC
44 PASSWORD 000 - 999 225
45 SPD AT MIN SIGNAL MINIMUM FREQUENCY - 999 Hz 0.0 Hz
46 SPD AT MAX SIGNAL MINIMUM FREQUENCY - 999 Hz 60.0 Hz
47 CLEAR HISTORY MAINTAIN (01), CLEAR (02) MAINTAIN (01)
48 PROGRAM USER SETTINGS (01), OEM SETTINGS (02), RESET
SELECTION RESET OEM (03), RESET 60 (04), 60 (04)
RESET 50 (05), TRANSLATE (06)
50 FAULT HISTORY (VIEW - ONLY) (N/A)
51 SOFTWARE CODE (VIEW - ONLY) (N/A)
52 DC BUS VOLTAGE (VIEW - ONLY) (N/A)
53 MOTOR VOLTAGE (VIEW - ONLY) (N/A)
54 LOAD (VIEW - ONLY) (N/A)
55 0 - 10 VDC INPUT (VIEW - ONLY) (N/A)
56 4-20 mA INPUT (VIEW - ONLY) (N/A)
57 TB STRIP STATUS (VIEW - ONLY) (N/A)
58 KEYPAD STATUS (VIEW - ONLY) (N/A)
PARAMETER MENU (cont)
NOTE 1: Factory defaults are shown for a 60 Hz base frequency. See Parameter 48 for 50
Hz base frequency.
Page 32
28
15.0 DESCRIPTION OF PARAMETERS
P01 LINE VOLTAGE SELECTION
This calibrates the drive for the actual applied input voltage. Set this parameter to HIGH (01)
for 120, 220-240 and 460-480 Vac input, or LOW (02) for 200-208 and 380-415 Vac input.
NOTE: If this parameter is changed while the drive is running, the new value will not take
effect until the drive is stopped.
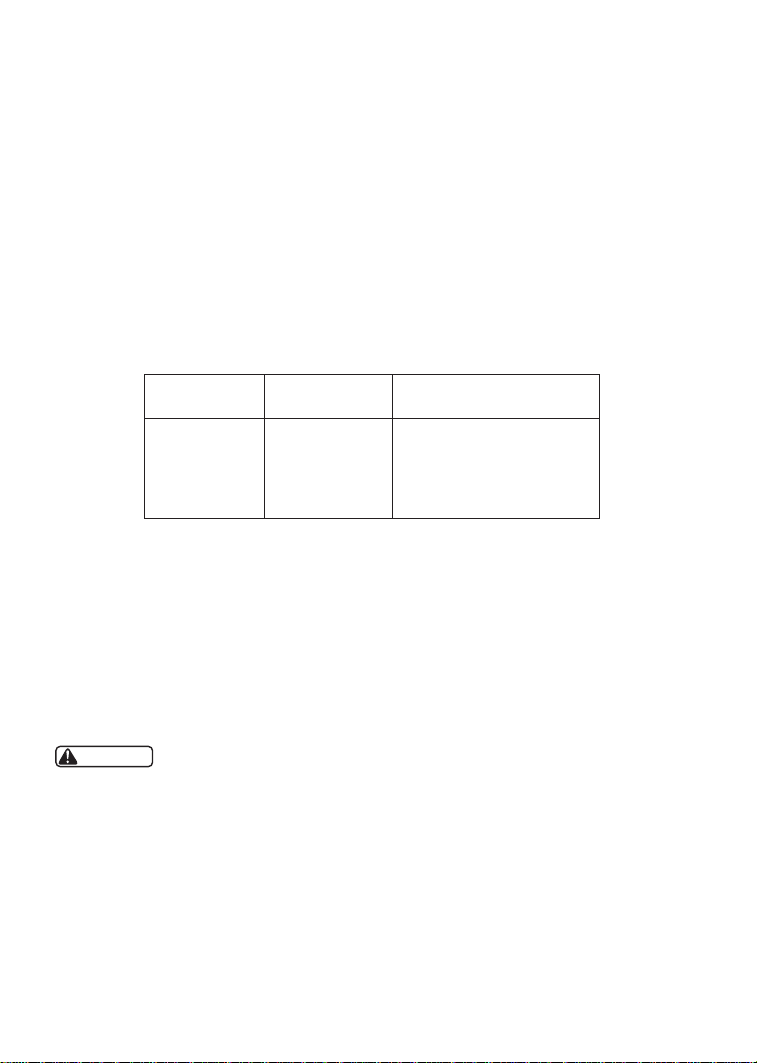
P02 CARRIER FREQUENCY
This sets the switching rate of the output IGBT’s. Increasing the carrier frequency will result in
less audible motor noise. Available settings are: 4 kHz, 6 kHz, 8 kHz, and 10 kHz.
PARAMETER CARRIER AMBIENT OR OUTPUT
SETTING FREQUENCY DERATE
01 4 kHz 40 C or 100 %
02 6 kHz 40 C or 100 %
03 8 kHz 40 C or 100 %
04 10 kHz 35 C or 92 %
NOTE:
• The SpinMaster™ drive is fully rated up to 8 kHz carrier frequency. If the 10 kHz carrier
frequency is selected, the drive’s ambient temperature rating OR output current rating must
be derated to the value shown in the table above.
• If this parameter is changed while the drive is running, the change will not take effect until
the drive is stopped.
P03 START METHOD
Automatic starting of equipment may cause damage to equipment and / or
injury to personnel! Automatic start should only be used on equipment that is inaccessible to
personnel.
01 NORMAL: The drive will start when the appropriate contact is closed on the terminal
strip. See Section 11 for possible control configurations.
02 START ON POWER UP: The drive will automatically start upon application of input
power.
03 START WITH DC BRAKE: When a START command is given, the drive will apply DC
BRAKE VOLTAGE (Parameter 22) for the duration of DC BRAKE TIME (Parameter 21)
prior to starting the motor to ensure that the motor is not turning.
WARNING
Page 33
04 AUTO RESTART WITH DC BRAKING: Upon a START command, after a fault, or upon
application of power, the drive will apply DC BRAKE VOLTAGE (Parameter 22) for the
duration of DC BRAKE TIME (Parameter 21) prior to starting (or restarting) the motor.
05 FLYING RESTART 1: LOW performance. Slowest synchronization and lowest current
level. This setting results in the smoothest synchronization.
06 FLYING RESTART 2: MEDIUM performance. Faster synchronization and higher current
level. This setting allows faster synchronization while retaining smoothness.
07 FLYING RESTART 3: HIGH performance. Fastest synchronization and highest current
level. This setting allows the fastest synchronization, but sacrifices smoothness.
When programmed for auto-restart (settings 04 - 07), the drive will attempt three restarts after
a fault. The interval between restart attempts is 15 seconds for setting 04, and 2 seconds for
settings 05, 06 and 07. During the interval between restart attempts, the display will read “SP”
to indicate Start Pending. If all three restart attempts fail, the drive will trip into FAULT LOCKOUT (displayed “LC”) and require a manual reset. Refer to Section 16.0 - TROUBLESHOOTING.
The FLYING RESTART 1 - 3 settings allow the drive to start into a spinning load after a fault or
upon application of input power. They differ in the time required to find the motor speed and
the amount of current required to synchronize with it. The faster the drive attempts to find the
motor speed, the more current is r equir ed. The first two restart attempts will try to start into the
spinning load, but the third restart attempt will act like AUTO RESTART WITH DC BRAKING.
NOTE: Settings 02 and 04 - 07 require a two-wire start/stop circuit to operate. The RUN
contact must remain closed for the power-up start and auto-restart functions to operate.
P04 STOP METHOD
01 COAST TO STOP: When a STOP command is given, the drive shuts off the output to
the motor, allowing it to coast freely to a stop.
02 COAST WITH DC BRAKE: When a stop command is given, the drive will activate DC
braking (after a delay of up to 2 seconds, depending on frequency) to help decelerate
the load. Refer to Parameters: 21 - DC BRAKE TIME, and 22 - DC BRAKE VOLTAGE.
03 RAMP TO STOP: When a stop command is given, the drive will decelerate the motor
to a stop at the rate determined by Parameter 20 - DECELERATION TIME.
04 RAMP WITH DC BRAKE: When a stop command is given, the drive will decelerate the
motor down to 0.2 Hz (at the rate set by Parameter 20 - DECELERATION TIME) and
then activate DC braking according to the settings of Parameters 21 - DC BRAKE TIME
and 22 - DC BRAKE VOLTAGE. This is used to bring the load to a final stop, as the motor
may still be turning slightly after the drive stops.
29
Page 34
30
P05 STANDARD SPEED SOURCE
This selects the speed reference source when the drive is in STANDARD speed mode. The
following speed reference can be selected.
01 KEYPAD: Use the L and M buttons to scroll to the desired speed.
02 PRESET SPEED #1: The drive will operate at the frequency set into Parameter 31.
03 0 - 10 VDC: The drive will respond to a 0 - 10 VDC signal wired to TB-5 (+) and
TB-2 (-).
04 4 - 20 mA: The drive will respond to a 4-20 mA signal wired to TB-25 (+) and
TB-2 (-).
P06 RELAY OUTPUT
This selects the status indication for the normally open relay output at TB-16 and TB-17.
01 NONE: Disables the open-collector output.
02 RUN: Closes upon a START command. Opens if the drive is in a STOP state, the drive
faults, or input power is removed. DC braking is considered a STOP state.
03 FAULT: Closes if there is no fault condition. Opens if the drive faults, or input power is
removed.
04 INVERSE FAULT: Closes is the drive faults. Opens if there is no fault condition.
05 FAULT LOCKOUT: Closes when input power is applied. Opens if three restart attempts
are unsuccessful, or if input power is removed.
06 AT SET SPEED: Closes if the drive is within ± 0.5 Hz of the speed setpoint.
07 ABOVE PRESET SPEED #3: Closes if the output frequency exceeds the PRESET SPEED
#3 setting. Opens if the output frequency is equal to or less than PRESET SPEED #3
(Parameter 33).
08 CURRENT LIMIT: Closes if the output current exceeds the CURRENT LIMIT setting. Opens
if the output current is equal to or less than CURRENT LIMIT (see Parameter 25).
09 AUTOMATIC SPEED MODE: Closes if an AUTOMATIC (terminal strip) speed reference is
active. Opens if a STANDARD (Parameter 5) speed reference is active.
10 REVERSE: Closes when reverse rotation is active. Opens when forward rotation is
active. (see Parameter 17 - ROTATION DIRECTION).
Page 35
31
P10 TB-13A FUNCTION SELECT
This selects the function of terminal TB-13A. Closing TB-13A to TB-11 (or opening in the case
of settings 08 and 10) activates the selected function. The following functions can be selected:
01 NONE: Disables the TB-13A function.
02 0-10 VDC: Selects a 0-10 VDC signal (at TB-5) as the AUTO speed reference input.
03 4-20 mA: Selects a 4-20 mA signal (at TB-25) as the AUTO speed reference input.
04 PRESET SPEED #1: Selects PRESET SPEED #1 as the AUTO speed reference. The drive
will operate at the frequency programmed into Parameter 31.
05 START FORWARD. Sets up the drive for a 3-wire start/stop circuit. Momentarily close
TB-13A to TB-11 to START the drive, and momentarily open TB-1 to TB-11 to STOP.
06 RUN REVERSE: Close TB-13A to TB-11 to RUN in the reverse direction, and open to
STOP. Close TB-1 to TB-11 to RUN in FORWARD DIRECTION and open to STOP.
07 START REVERSE: Momentarily close TB-13A to TB-11 to START the drive in the reverse
direction and momentarily open TB-1 to TB-11 to STOP. Parameter 17 - ROTATION must
be set to FORWARD AND REVERSE (02), and TB-13E must be used for START
FORWARD.
08 EXTERNAL FAULT: Sets TB-13A as a normally closed external fault input. Open TB-13A
to TB-11 to trip the drive.
09 INVERSE EXTERNAL FAULT: Sets TB-13A as a normally open external fault input. Close
TB-13A to TB-11 to trip the drive.
10 AUXILIARY STOP: When TB-13A is opened with respect to TB-11, the drive will
decelerate to a STOP (even if STOP METHOD is set to COAST) at the rate set into
ACCEL/DECEL #2 (Parameter 42).
11 ACCEL/DECEL #2: Selects the acceleration and deceleration time programmed into
ACCEL/DECEL #2 (Parameter 42).
P11 TB-13B FUNCTION SELECT
This selects the function of terminal TB-13B. Closing TB-13B to TB-11 (or opening in the case
of setting 09 and 11) activates the selected function. The following functions can be selected:
01 NONE: Disables the TB-13B function.
02 0-10 VDC: Selects a 0-10 VDC signal (at TB-5) as the AUTO speed reference input.
Page 36
32
03 4-20 mA: Selects a 4-20 mA signal (at TB-25) as the AUTO speed reference input.
04 PRESET SPEED #2: Selects PRESET SPEED #2 as the speed reference. The drive will
operate at the frequency programmed into Parameter 32.
05 DECREASE FREQ: Closing TB-13B to TB-11 will decrease the speed setpoint until the
contact is opened. TB-13E must be programmed for INCREASE FREQ.
06 START FORWARD: Sets up the drive for a 3-wire start/stop circuit. Momentarily close
TB-13B to TB-11 to start the drive, and momentarily open TB-1 to TB-11 to stop.
07 JOG FORWARD: Close TB-13B to TB-11 to JOG in the forward direction. The drive will
run at PRESET SPEED #2 (Parameter 32) when in JOG mode.
08 JOG REVERSE - Close TB-13B to TB-11 to JOG in the reverse direction. The drive will run
at PRESET SPEED #2 (Parameter 32 when in JOG mode.
When operating in JOG mode, the STOP signal and the AUXILIARY STOP
function (see Parameters 10-12), or the STOP key on the optional remote keypad WILL NOT
stop the drive. To stop the drive, remove the JOG command.
JOG REVERSE will operate the drive in reverse even if ROTATION DIRECTION
(Parameter 17) is set to FORWARD ONLY.
09 EXTERNAL FAULT: Sets TB-13B as a normally closed external fault input. Open TB-13B
to TB-11 to trip the drive.
10 INVERSE EXTERNAL FAULT: Sets TB-13B as a normally open external fault input. Close
TB-13B to TB-11 to trip the drive.
11 AUXILIARY STOP: When TB-13B is opened with respect to TB-11, the drive will
decelerate to a STOP (even if STOP METHOD is set to COAST) at the rate set into
ACCEL/DECEL #2 (Parameter 42).
12 ACCEL/DECEL #2: Selects the acceleration and deceleration time programmed into
Parameter 42 - ACCEL/DECEL #2.
13 REMOTE KEYPAD: When the Remote Keypad option is being used, TB-13B must be set
to this function. Also, TB-13E (Parameter 12) must be set for REMOTE KEYPAD (21), and
CONTROL (Parameter 14) must be set to REMOTE KEYPAD ONLY (02).
NOTE: If the drive is commanded to JOG when running, the drive will enter JOG mode and
run at PRESET SPEED #2 (Parameter 32). When the JOG command is removed, the drive will
STOP.
WARNING
WARNING
Page 37
P12 TB-13E FUNCTION SELECT
This selects the function of terminal TB-13E. This terminal can be configured as a digital input
(settings 01 to 10) or a digital status output (settings 11 to 20). When used as an input,
closing TB-13E to TB-11 (or opening in the case of settings 07 and 09) activates the selected
function.
When used as an output, it can provide the drive’s status for monitoring. If the Remote Keypad
option is being used, this parameter must be set to REMOTE KEYPAD (21).
The following input functions can be selected:
01 NONE: Disables the TB-13E function.
02 0-10 VDC: Selects a 0-10 VDC signal (at TB-5) as the AUTO speed reference input.
03 4-20 mA: Selects a 4-20 mA signal (at TB-25) as the AUTO speed reference input.
04 PRESET SPEED #3: Selects PRESET SPEED #3 as the speed reference. The drive will
operate at the frequency programmed into Parameter 33.
05 INCREASE FREQ: Closing TB-13E to TB-11 will increase the speed setpoint until the
contact is opened. INCREASE FREQ will only work when the drive is running. TB-13B
must be programmed for DECREASE FREQ.
06 START FORWARD: Sets up the drive for a 3-wire start/stop circuit. Momentarily close
TB-13E to TB-11 to start the drive, and momentarily open TB-1 to TB-11 to stop.
07 EXTERNAL FAULT: Sets TB-13E as a normally closed external fault input. Open TB-13E
to TB-11 to trip the drive
08 INVERSE EXTERNAL FAULT: Sets TB-13E as a normally open external fault input. Close
TB-13E to TB-11 to trip the drive.
09 AUXILIARY STOP: When TB-13E is opened with respect to TB-11, the drive will
decelerate to a STOP (even if STOP METHOD is set to COAST) at the rate set into
ACCEL/DECEL #2 (Parameter 42).
10 ACCEL/DECEL #2: Selects the acceleration and deceleration time programmed into
ACCEL/DECEL #2 (Parameter 42).
The following output functions can be selected. The terms “open” and “close” refer to the state
of the internal transistor that activates the circuit. When the transistor is “closed” the circuit is
complete, and TB-13E is pulled up to 15 VDC (when “open”, TB-13E is at 0 VDC potential).
11 RUN: Closes upon a START command. Opens if the drive is in a STOP state, the drive
faults, or input power is removed. DC braking is considered a STOP state.
33
Page 38
34
12 FAULT: Closes if there is no fault condition. Opens if the drive faults, or input power is
removed.
13 INVERSE FAULT: Closes if the drive faults. Opens if there is no fault condition.
14 FAULT LOCKOUT: Closes when input power is applied. Opens if three restart attempts
are unsuccessful, or if input power is removed.
15 AT SET SPEED: Closes if the drive is within ± 0.5 Hz of the speed setpoint.
16 ABOVE PRESET SPEED #3: Closes if the output frequency exceeds PRESET SPEED #3
(Parameter 33). Opens if the output frequency is equal to or less than PRESET SPEED
#3.
17 CURRENT LIMIT: Closes if the output current exceeds the CURRENT LIMIT setting. Opens
if the output current is equal to or less than CURRENT LIMIT (see Parameter 25).
18 AUTOMATIC SPEED MODE: Closes if an AUTOMATIC (terminal strip) speed reference is
active. Opens if a STANDARD (Parameter 5) speed reference is active.
19 REVERSE: Closes when reverse rotation is active. Opens when forward rotation is active
(see Parameter 17 - ROTATION DIRECTION).
20 DYNAMIC BRAKING: TB-13E becomes the “trigger” that activates the optional external
Dynamic Braking module. Refer to the instructions included with the Dynamic Braking
option.
21 REMOTE KEYPAD: When the Remote Keypad option is being used, TB-13E must be set
for this function. Also, TB-13B (Parameter 11) must be set for Remote Keypad (13) and
CONTROL (Parameter 14) must be set for REMOTE KEYPAD ONLY (02).
P14 CONTROL
This selects the source of START/STOP and direction commands.
01 TERMINAL STRIP ONLY: The drive will only respond to START/STOP and direction
commands from the terminal strip.
02 REMOTE KEYPAD ONLY: The drive will only respond to START/STOP and direction
commands from the optional remote keypad. Terminals 13B and 13E must also be set
for the REMOTE KEYPAD option (refer to Parameters 12 and 13).
Page 39
35
P16 UNITS EDITING
This allows parameter and keypad speed editing in whole units or tenths of units above 100.
Below 100, the value can always be changed by tenths of units.
01 TENTHS OF UNITS: The value can always be changed by tenths of units (up to a value
of 1000). If the L or M button is pressed and held, the value will change by tenths of
units until the next whole unit is reached, and then the value will change by whole
units. Refer to Section 13.1.
02 WHOLE UNITS: The value can be changed by tenths of units until 99.9 is reached.
Above 99.9, the value will change in whole unit increments only. Below a value of
100, if the L or M button is pressed and held, the value will change by tenths of units
until the next whole unit is reached, and then the value will change by whole units.
P17 ROTATION DIRECTION
01 FORWARD ONLY: The drive will only allow rotation in the forward direction. However,
JOG REVERSE (see Parameter 11) will still operate even if FORWARD ONLY is selected.
02 FORWARD AND REVERSE: The drive will allow rotation in both directions.
P19 ACCELERATION TIME
This sets the acceleration rate for all of the speed reference sources (keypad, speed pot,
jog, MOP, and preset speeds). This setting is the time to accelerate from 0 Hz to the BASE
FREQUENCY (Parameter 27).
P20 DECELERATION TIME
This sets the deceleration rate for all of the speed reference sources (keypad, speed pot, jog
MOP, and preset speeds). This setting is the time to decelerate from BASE FREQUENCY to 0 Hz..
If the drive is set for COAST TO STOP (setting 01 or 02 in Parameter 04), this parameter will
have no effect when a STOP command is given.
P21 DC BRAKE TIME
This sets the length of time that the DC braking voltage is applied to the motor. The DC BRAKE
TIME should be set to the lowest value that provides satisfactory operation in order to minimize
motor heating.
P22 DC BRAKE VOLTAGE
This sets the magnitude of the DC braking voltage, in percentage of the line voltage. The point
at which the DC braking is activated depends on the selected STOP METHOD (Parameter 04):
Page 40
36
If COAST WITH DC BRAKE is selected, the DC braking is activated after a time delay of up to 2
seconds, depending on the output frequency at the time of the STOP command. In this case,
the DC braking is the only force acting to decelerate the load.
If RAMP WITH DC BRAKE is selected, braking is activated when the output frequency reaches
0.2 Hz. In this case, the drive decelerates the load to a near stop and the DC braking is used
to bring the load to a final stop.
P23 MINIMUM FREQUENCY
This sets the minimum output frequency of the drive for all speed refer ence sources except the
PRESET SPEEDS (Parameters 31-37), and is used with MAXIMUM FREQUENCY (Parameter 24)
to define the operating range of the drive.
When using an analog speed reference (0-10 VDC or 4 mA), Parameters 45 and 46 (SPEED AT
MIN SIGNAL and SPEED AT MAX SIGNAL) also affect the drive’s speed range.
NOTE: If this parameter is changed while the drive is running, the new value will not take
effect until the drive is stopped.
P24 MAXIMUM FREQUENCY
This sets the maximum output frequency of the drive for all speed reference sources, and is
used with MINIMUM FREQUENCY (Parameter 23) to define the operating range of the drive.
When using an analog speed reference (0-10 VDC or 4-20 mA), Parameters 45 and 46 (SPEED
AT MIN SIGNAL and SPEED AT MAX SIGNAL) also affect the drive’s speed range.
NOTE: If this parameter is changed while the drive is running, the new value will not take
effect until the drive is stopped.
P25 CURRENT LIMIT
This sets the maximum allowable output current of the drive. The maximum setting is either
180% or 150%, depending on whether LINE VOLTAGE SELECTION (Parameter 01) is set to
HIGH or LOW.
If the load demands more current than the CURRENT LIMIT setting, the drive will reduce the
output frequency in an attempt to reduce the output curr ent. When the overcurrent condition
passes, the drive will accelerate the motor back up to the speed setpoint.
P26 MOTOR OVERLOAD
The SpinMaster™ is UL approved for solid state motor overload protection, and therefore does
not require a separate thermal overload relay for single motor applications. The drive contains
an adjustable thermal overload circuit that protects the motor from excessive overcurrent. This
circuit allows the drive to deliver up to 150% current for one minute. If the overload circuit
“times out”, the drive will trip into an OVERLOAD fault (displayed as “PF”).
Page 41
37
P27 BASE FREQUENCY
The BASE FREQUENCY determines the V/Hz ratio by setting the output frequency at which the
drive will output full voltage to the motor. In most cases, the BASE FREQUENCY should be set
to match the motor’s rated frequency.
Example: A 230 Vac, 60 Hz motor requires a V/Hz ratio of 3.83 (230 V / 60 Hz = 3.83 V/Hz)
to produce full torque. Setting the BASE FREQUENCY to 60 Hz causes the drive to output
full voltage (230 Vac) at 60 Hz, which yields the required 3.83 V/Hz. Output voltage is
proportional to output frequency, so the 3.83 V/Hz ratio is maintained from 0 - 60 Hz,
allowing the motor to produce full torque from 2 Hz (below 2 Hz there is less torque due to
slip) up to 60 Hz.
NOTE: If this parameter is changed while the drive is running, the new value will not take
effect until the drive is stopped.
P28 FIXED BOOST
FIXED BOOST increases starting torque by increasing the output voltage when operating
below half of the base frequency. For better out-of-the-box performance, SpinMaster™ drives
are shipped with a setting that is different from the factory default of 1%. Units rated 0.33 to
1 HP (0.25 to 0.75 kW) are set to 5.3%, units rated 1.5 to 2 HP (1.1 to 1.5 kW) are set to 4.4%,
3 HP (2.2kW) units are set to 3.6%, 5 HP (4.0 kW) units are set to 3.0%, units rated 7.5 HP
(5.5 kW) are set to 2.7%, units rated 10 HP (7.5 kW) are set to 2.4%, and units rated 15 HP
(11 kW) are set to 2.2%.
P29 ACCELERATION BOOST
ACCELERATION BOOST helps accelerate high-inertia loads. During acceleration, the output
voltage is increased to increase motor torque. Once the motor reaches the new speed
setpoint, the boost is turned off and the output voltage returns to the normal value.
P30 SLIP COMPENSATION
SLIP COMPENSATION is used to counteract changes in motor speed (slip) caused by changes
in load. In a standard AC induction motor, the shaft speed decreases as load increases, and
increases as load decreases. By increasing or decreasing the output frequency in response to
an increasing or decreasing load, the slip is counteracted and speed is maintained. Most
standard NEMA B motors have a 3% slip rating.
Page 42
38
P31 - P37 PRESET SPEED #1 - #7
Preset speeds are activated by contact closur es between TB-11 and TB-13A, 13B, and 13E. The
TB-13 terminals must be programmed as preset speed selects using Parameters 10-12.
NOTE: Preset speeds can operate below the frequency defined by the Minimum
Frequency parameter (Parameter 23).
Refer to the table below for activation of the preset speeds using the TB-13 terminals.
NOTE: When TB-13 terminal is programmed for a function other than a preset speed select,
it is considered OPEN for the table above.
Preset Speed #6 and #7 can also be used as skip frequencies to restrict the drive from
operating at frequencies that cause vibration in the system. See Parameter 38 below.
P38 SKIP BANDWIDTH
The SpinMaster™ drive has two skip frequencies that can be used to lock out critical frequencies that cause mechanical resonance in the system. Once SKIP BANDWIDTH is set to a
value other than 0 Hz, the skip frequencies are enabled. When the skip frequency function is
enabled, PRESET SPEED #6 and #7 are used as the skip frequencies. SKIP BANDWIDTH sets the
range above the skip frequencies that the drive will not operate within.
Example: The critical frequency is 23 Hz, and it is desired to skip a frequency range of 3 Hz
above and below the critical frequency (therefor e the skip range is 20 to 26 Hz). PRESET SPEED
#6 or #7 would be set to 20 Hz, and the SKIP BANDWIDTH would be set to 6.0 Hz.
If the drive is running at a speed below the skip range, and it is given a speed command that
is within the skip range, the drive will accelerate to the start of the skip range (20 Hz in the
example) and run at the speed until the speed command is greater than or equal to the “top”
of the skip range. The drive will then accelerate through the skip range to the new speed.
Likewise, if the drive is running at a speed above the skip range, and it is given a speed
command that is within the skip range, the drive will decelerate to the “top” of the skip range
(26 Hz in the example) and run at that speed until the speed command is less than or equal
to the “bottom” of the skip range. The drive will then decelerate through the skip range to the
new speed.
SPEED # TB-13A TB-13B TB-13C
1 CLOSED OPEN OPEN
2 OPEN CLOSED OPEN
3 OPEN OPEN CLOSED
4 CLOSED CLOSED OPEN
5 CLOSED OPEN CLOSED
6 OPEN CLOSED CLOSED
7 CLOSED CLOSED CLOSED
Page 43
39
NOTE: PRESET SPEEDS #6 and #7 can still be used as preset speeds even if they ar e also being
used as skip frequencies.
P39 SPEED SCALING
This scales the display to indicate speed in units other than frequency. This parameter should
be set to the desired display value when the drive output is 60 Hz. The highest setting is 6500,
and the highest value that can be displayed is 6553.6. If SPEED SCALING is set to 0.0, the
speed scaling function is disabled and the display will indicate frequency.
Example: A machine produces 175 parts per hour when the motor is running at 60 Hz.
Setting the SPEED SCALING to 175 will calibrate the drive’s display to read 175 when the motor
is running at 60 Hz. This is a linear function, so at 30 Hz the display would read 87.5, and at
120 Hz, the display would read 350.
NOTE:
• If the displayed value will exceed 999, the value is shown in two parts. For example, if the
displayed value is 1800, the display will indicate this by toggling between “1- -” and “800’.
• If SPEED SCALING is set such that the maximum displayable value (6553.6) is exceeded,
the display will flash “9999” to indicate that the value is out of range. For example, if SPEED
SCALING is set to 6000, the drive will display 6000 when it is running at 60 Hz. If the speed
is increased past 65.5 Hz (at 65.5 Hz, the scaled value would be 6550), the display will
flash “9999” because a scaled value above 6553.6 cannot be displayed.
P42 ACCEL / DECEL #2
This parameter sets the second acceleration and deceleration rate of the drive, which can be
activated using terminals TB-13A, 13B, or 13E (Parameter 10, 11, or 12).
P44 PASSWORD
This allows the PASSWORD to be changed to any number between 000 and 999. Setting
PASSWORD to 000 disables the password function.
NOTE: The factory default password is 225.
P45 SPEED AT MIN SIGNAL
This sets the speed at which the drive will run when it receives the minimum speed reference
signal (0 VDC or 4 mA). This is used in conjunction with SPEED AT MAX SIGNAL (Parameter 46)
to define the speed range of the drive when following an analog speed reference signal.
P46 SPEED AT MAX SIGNAL
This sets the speed at which the drill will run when it receives the maximum speed reference
signal (10 V DC or 20 mA). This is used in conjunction with SPEED AT MIN SIGNAL (Parameter
45) to define the speed range of the drive when following an analog speed reference signal.
Page 44
40
NOTE: If SPEED AT MIN SIGNAL is set higher than SPEED AT MAX SIGNAL, the drive will react
inversely to the speed reference signal. Therefore, as the speed reference signal increases, the
drive speed will decrease, and vice-versa.
P47 CLEAR FAULT HISTORY
01 MAINTAIN: Maintains the FAULT HISTORY (Parameter 50) entries for troubleshooting.
02 CLEAR: Erases the FAULT HISTORY (Parameter 50) entries.
P48 PROGRAM SELECTION
This is used to select whether the drive will operate according to the user settings or the
optional OEM default settings, and to reset the parameters to default settings. Refer to Section
13.2.
01 OPERATE WITH USER SETTINGS: The drive will operate according to the users settings.
Operation in USER mode allows the parameter values to be changed to suit any
application.
02 OPERATE WITH OEM DEFAULTS: The drive will operate according to the optional OEM
default settings, which configure the drive for a specific application. When operating
in OEM mode, the parameter values can be viewed, but not changed. If an attempt is
made to change a parameter setting, the display will flash “GE”. If the drive is not
programmed with OEM default settings, the display will flash “GF” if this option is selected.
03 RESET OEM: Resets the user parameters to the OEM default settings. If the drive is not
programmed with OEM default settings, the display will flash “GF” if this option is
selected.
04 RESET 60: Resets the users parameters to the factory defaults for a 60 Hz base
frequency. Parameters 24, 27, and 46 will reset to 60.0 Hz.
05 RESET 50: Resets the user parameters to the factory defaults for a 50 Hz base
frequency. Parameters 24, 27, and 46 will reset to 50.0 Hz.
06 TRANSLATE: If an EPM from a drive with a previous (but compatible) parameter version
is installed in a new drive, the new drive will function like the previous version drive,
but none of the parameter settings can be changed (“cE” will be displayed if this is
attempted). The TRANSLATE function converts the EPM to the new parameter version
so that the parameters can be changed, but it also retains the old parameter settings
so the new dive will operate like the old drive without having to re-program all of the
parameters. Once the EPM is “translated”, it will no longer work in the old drive.
Page 45
41
NOTE:
• If the user parameters are reset to the OEM defaults (using the RESET OEM option), and
then OPERATE WITH USER SETTINGS is selected, the USER settings will be the same as the
OEM default settings. This allows the drive to operate as if it was in OEM mode, but the
parameter values can be changed. This is useful if some of the OEM default settings need
to be fine-tuned for proper operation. The new parameter values are not actually stor ed as
new OEM default settings however, they are simply stored as new USER settings.
Therefore, if the parameters are reset to the OEM defaults again, the parameters that were
changed will be reset to their “old” value. The optional EPM Programmer is required to
change OEM default settings. Refer to Section 13.2.
• Only the TRANSLATE (06) function can be performed while the drive is running. The
display will flash “Er” if an attempt is made to select any other function while the drive is
running.
P50 FAULT HISTORY
The FAULT HISTORY stores the last eight faults that tripped the drive. Refer to Section 16.0 TROUBLESHOOTING for a list of the faults and possible causes.
Use the L and M buttons to scroll through the fault entries. The faults are stored from newest
to oldest, with the first fault shown being the most recent.
The display will read “_ _” if the FAULT HISTORY does not contain any fault messages.
P51 SOFTWARE VERSION
This displays the software version number for the control board software. This information is
useful when contacting the factory for programming or troubleshooting assistance.
The software version is displayed in two parts which alternate. The first part is the software
version, and the second part is the revision number. For example, if the display flashes “94”
and “02”, this indicates that the drive contains the second revision of version 94 software.
P52 DC BUS VOLTAGE
This displays the DC bus voltage in percent of nominal. Nominal DC bus voltage is determined
by multiplying the drive’s nameplate input voltage rating by 1.4.
P53 MOTOR VOLTAGE
This displays the output voltage in percent of the drive’s nameplate output voltage rating.
P54 MOTOR LOAD
This displays the motor load in percent of the drive’s output current rating.
Page 46
42
P55 0-10 VDC INPUT
This displays the level of the 0-10 VDC input signal at TB-5. A reading of 100% indicates a
10 VDC input at TB-5.
P56 4-20 mA INPUT
This displays the level of the 4-20 mA input signal at TB-25. A reading of 20% indicates a 4 mA
input at TB-25, and a reading of 100% indicates a 20 mA input at TB-25.
P57 TERMINAL STRIP STATUS
This indicates that status of several terminals using the vertical segments of the LED display. An
illuminated segment indicates that the particular terminal is closed to TB-11. See the diagram
below:
P58 KEYPAD AND PROTECTION STATUS
This indicates the status of the buttons on the keypad, and the status of the protective
circuitry in the drive, using the horizontal segments of the LED. An illuminated segment
indicates that the corresponding button is pressed, or the protective circuit is active. See the
diagram below:
NOTE: FCLIM is an abbreviation for Fast Current Limit.
Mode
FCLIM
OUTPUT
FAULT
TB-1 TB-13A
TB-13B
TB-13E
(input)
TB-13E
(output)
FACTORY
RESERVED
Page 47
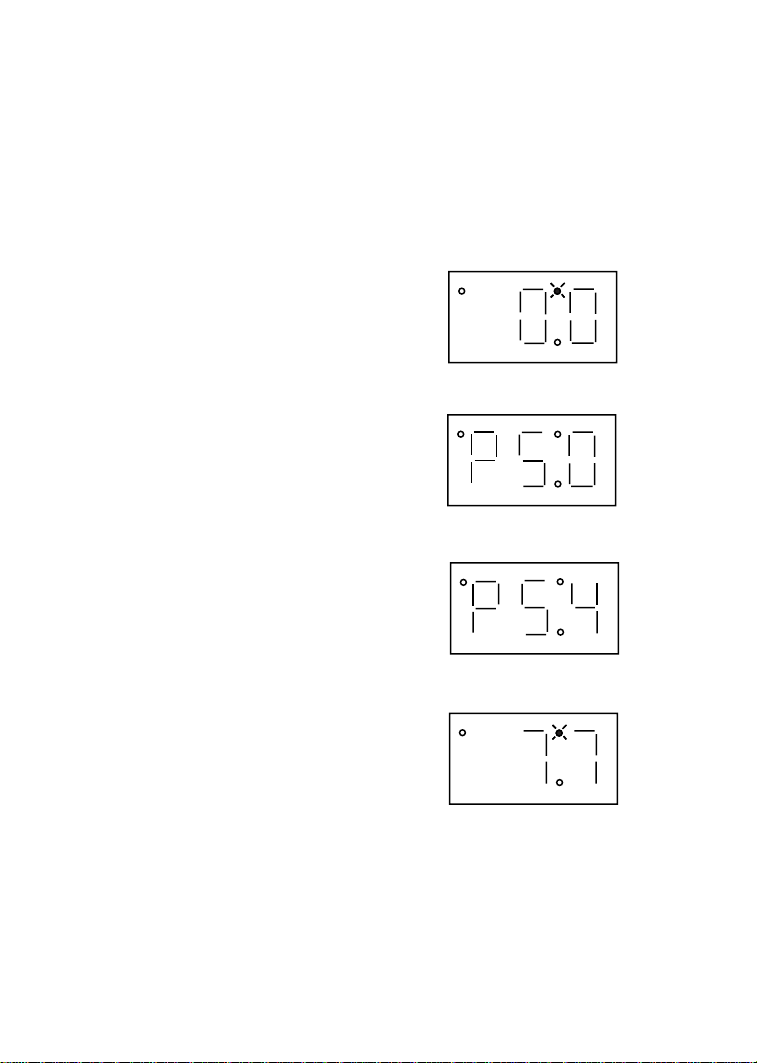
43
16.0 TROUBLESHOOTING
To aid in troubleshooting, Parameters 50 through 60 can be accessed without entering the
PASSWORD. Simply press the Mode button twice to “skip” over the PASSWORD prompt, and
“P50” will be displayed to indicate that the parameter menu has been entered and Parameter
50 (FAULT HISTORY) can be viewed. The L and M buttons can be used to scroll from
Parameter 50 to Parameter 60. Once the desired parameter is found, press the Mode button
to view its “contents”. When finished, press Mode to exit the parameter menu. An example is
shown below:
Press Mode once
Display reads “00”
Upper right decimal point blinks
Press Mode again
Display reads “P50” (FAULT HISTORY)
Use L and M to scroll to the desired
parameter number
(In this example Parameter 54 has been
selected, which is MOTOR LOAD)
Press Mode to view parameter contents
(77 = 77% LOAD)
Upper right decimal point blinks
Press Mode again to exit
In the example above, Parameter 54 - MOTOR LOAD is being viewed. The “77” in the
example indicates that the load on the motor is 77% of the output current rating of the drive.
Page 48
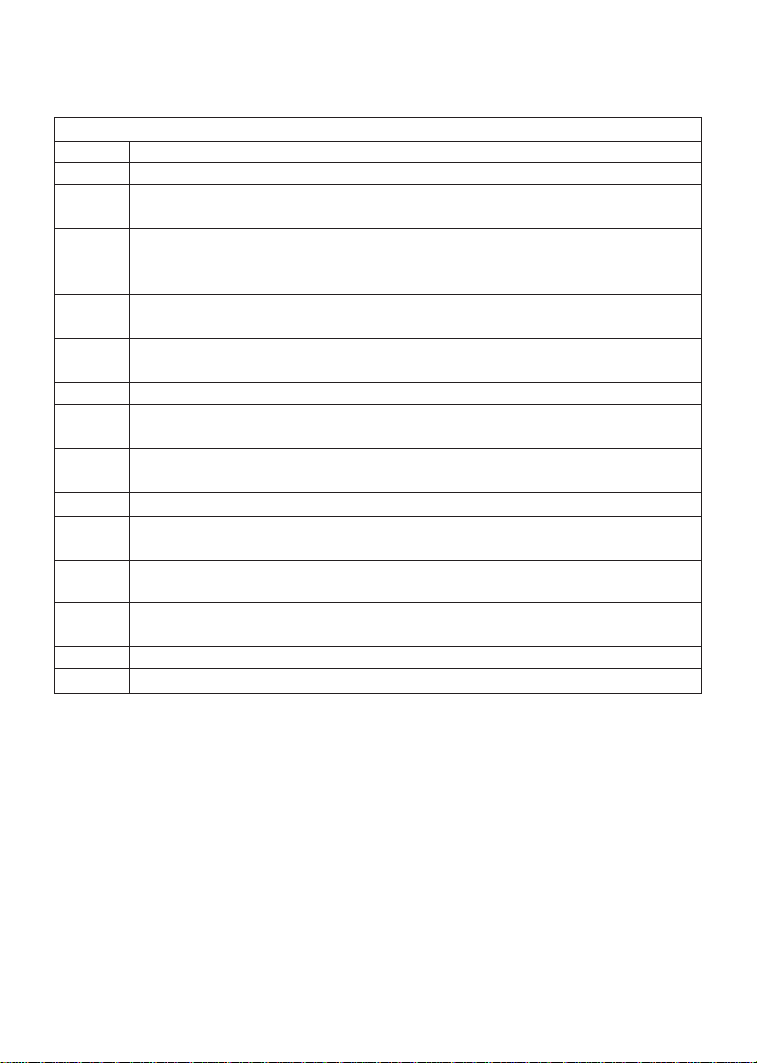
44
The table below lists the fault conditions that will cause the drive to shut down, as well as some
possible causes. Please contact the factory for more information on troubleshooting faults.
To clear a fault, issue a STOP command on the terminal strip,. The fault will only clear if the
condition that caused the fault has passed. For example, if the drive trips on a LOW DC
BUS VOLTAGE FAULT (LF) due to low input voltage, the fault cannot be cleared until the input
voltage returns to a normal level.
If the drive is programmed to automatically restart after a fault (see Parameter 03), the drive
will attempt to restart three times after a fault (the drive will not restart after CF, cF, GF, FC, F1,
F2-F9, or Fo faults). If all three restart attempts are unsuccessful, the drive will trip into FAULT
LOCKOUT (LC), which requires a manual reset as described above.
FAULT MESSAGES
FAULT DESCRIPTION & POSSIBLE CAUSES
AF High Temperature Fault: Ambient temperature is too high; Cooling fan has failed (if equipped).
CF Control Fault: A blank EPM, or an EPM with corrupted data has been installed. Perform a
factory reset using Parameter 48 - PROGRAM SELECTION.
cF Incompatibility Fault: An EPM with an incompatible parameter version has been installed.
Either remove the EPM or perform a factory reset (Parameter 48) to change the parameter
version of the EPM to match the parameter version of the drive.
dF Dynamic Braking Fault: The drive has sensed that the dynamic braking resistors are over-
heating and shuts down to protect the resistors.
EF External Fault: One of the TB-13 terminals is set as an External Fault input and that terminal
is open with respect to TB-11.Refer to Parameters 10, 11 and 12.
GF Data Fault:User data and OEM defaults in the EPM are corrupted.
HF High DC Bus Voltage Fault: Line voltage is too high; Deceleration rate is too fast; Overhauling
load. For fast deceleration or overhauling loads, dynamic braking may be required.
JF Remote Keypad Fault: The communication link between the drive and the optional Remote
Keypad has been lost.Check for proper wiring and/or noise.
LF Low DC Bus Voltage Fault: Line voltage is too low.
OF Output Transistor Fault: Phase to phase or phase to ground short circuit on the output; Boost
settings are too high; Acceleration rate is too fast;Failed output transistor.
PF Current Overload Fault: VFD is undersized for the application; Mechanical problem with the
driven equipment.
UF Start Fault: Start command was present when the drive was powered up.Must wait 2 seconds
after power-up to apply Start command if START METHOD is set to NORMAL.
F1 EPM Fault:The EPM is missing or damaged.
FC,F2 - F9, Fo Internal Faults: The control board has sensed a problem - consult factory.
Page 49
45
17.0 SpinMaster™ DISPLAY MESSAGES
The following describes the various displays and messages that can appear on the
SpinMaster™ drive.
17.1 SPEED DISPLAY
If the drive is in a STOP state (indicated by “_ _ _” on the display), and the commanded speed
is changed, the display will show the commanded speed, and the upper left decimal point will
turn on solid. About five seconds after a change is made, the display will begin to alternate
between the commanded speed value and the “_ _ _” display. If the Mode button is pressed,
the display will stop alternating and show the “_ _ _” display only.
When the drive is given a START command, the displayed speed will start increasing as the
drive accelerates up to the commanded speed. If the commanded speed is changed while the
drive is running, the display will show the commanded speed rather than the actual speed,
until the actual speed reaches the commanded speed.
If the commanded speed is changed faster than the drive can accelerate or decelerate, the
upper left decimal point will blink to indicate that the drive is accelerating or decelerating to
the new speed. Once the actual speed reaches the commanded speed, the upper left decimal
point will turn on solid for 5 seconds and then turn off to indicate that the commanded speed
has been reached, and that the display is now showing the actual speed.
17.2 CHANGING THE SPEED REFERENCE SOURCE
When the speed source is changed while the drive is running, the display will flash the message for the new speed source to indicate that the new speed source is active. Also, if the drive
is being controlled from a speed sour ce other than the L and M buttons (0-10 VDC, 4-20 mA,
etc), and one of the L or M buttons is pressed, the display will flash the present speed source
message to indicate that the L and M buttons are invalid.
Example 1: The drive is running and the present speed source is the keypad. TB-13A is
programmed to select a 4-20 mA signal as the speed source. When TB-13A is closed to TB-11,
the display will flash “EI” to indicate that the speed source has changed to the 4-20 mA signal.
If the contact between TB-13A and TB-11 is opened, the display will flash “CP” to indicate that
the speed source has changed back to the L and M buttons.
Example 2: The speed source is a 0-10 VDC signal. If the L or M button is pushed, the
display will flash “EU” to indicate that the present speed source is the 0-10 VDC signal and that
the L and M buttons are invalid.
Refer to the table on the next page for the possible speed reference source displays:
Page 50
46
NOTE: The speed source displays will flash when the speed reference source is changed
while the drive is running to indicate that the new speed reference source is active.
17.3 STATUS AND WARNING MESSAGES
SPEED SOURCE DISPLAYS
DISPLAY DESCRIPTION
CP CONTROL PAD: Speed is set using the Land Mbuttons on the front of the drive.
EI EXTERNAL CURRENT:Speed is controlled by a 4-20 mA signal wired to TB-25 and TB-2.
EU EXTERNAL VOLTAGE: Speed is controlled by a 0-10 VCD signal wired to TB-5 and TB-2.
JG JOG: The drive is in Jog mode, and the speed is set by Preset Speed #2 (Parameter 32).
OP MOP (Motor Operated Pot): Contacts wired to TB-13B and TB-13E are used to increase and
decrease the drive speed.
Pr1 - Pr7 PRESET SPEEDS #1-7: Speed is set by the indicated Preset Speed (Parameters 31-37).
STATUS AND WARNING MESSAGES
DISPLAY DESCRIPTION
br DC BRAKING:The DC braking circuit is activated.
cE “cE” will be displayed if an EPM with a different parameter version is installed and then an
attempt is made to change parameter settings without performing the TRANSLATE function.
Refer to PROGRAM SELECTION (Parameter 48).
CL CURRENT LIMIT: The output current has exceeded the CURRENT LIMIT setting (Parameter
25) and the drive is reducing the output frequency to reduce the output current. If the drive
remains in CURRENT LIMIT for too long, it can trip into a CURRENT OVERLOAD fault (PF).
Er ERROR: Invalid data has been entered or an invalid command was attempted.
GE “GE” will be displayed if an attempt is made to change the OEM default settings when the drive
is operating in the OEM mode (see Parameter 48).
GF If “GF”is displayed when a RESET OEM is attempted, it indicates that the OEM defaults in the
EPM are corrupted. If “GF”is displayed upon power-up, it indicates that the OEM defaults and
the user settings in the EPM are corrupted. Refer to Section 13.2.
LC FAULT LOCKOUT:The drive has f ailed three restart attempts and now requires a manual reset.
SE SERIAL: The optional remote keypad is active as the user interface instead of the buttons on
the front of the drive. See Parameter 14 - CONTROL.
SP START PENDING:“SP” blinks during the interval between restart attempts.
DECEL OVERRIDE (both upper decimal points blinking):The drive has stopped decelerating
to avoid tripping into an HF fault due to regenerative energy from the motor.
Page 51
EC DECLARATION OF CONFORMITY
In accordance with EN45014:1998
Applied Council Directive(s): EMC Directive 89/336/EEC, as amended:
92/31/EEC and 93/68/EEC, and Low Voltage Directive 73/23/EEC, as
amended: 93/68/EEC
We REGAL-BELOIT CORPORATION
200 State Street
Beloit, WI 53511-6254
U.S.A.
declare under our sole responsibility that the products to which this
Declaration relates, are in conformity with the relevant provisions of the
following standards, provided that installations are carried out in accordance
with manufacturer’s instructions.
PRODUCTS RELATED TO DECLARATION
SpinMaster™ AC Variable Frequency Motor Drives Models:
T201 T212 T217 T225 T230 T236
T202 T213 T220 T226 T231 T237
T204 T214 T221 T227 T232 T238
T205 T215 T222 T228 T234 T239
T211 T216 T224 T229 T235
RELEVANT EUROPEAN STANDARDS
EN 61800-3* Adjustable speed electrical power drive systems, Part 3 - EMC
product standard, including specific test methods
EN 50178 Electronic equipment for use in power installations
* with suitable line filters that are properly installed.
YEAR OF CE Marking (Low Voltage Directive): 2001
Signature:
John Rydeski, Agency Project Engineer
Dated this 16th day of January 2002.
REGAL-BELOIT
Variable Speed AC Motors Drives
Page 52
A REGAL-BELOIT COMPANY
100 E. Randolph Street • P.O.Box 8003 • Wausau, WI 54402-8003
715-675-3311 • Fax:715-675-8030
www.marathonelectric.com
®
SB182 REV 2/5707M/750/11-06/FS/BH
 Loading...