

Page 1

Features
• High-performance, Low-power AVR
• Advanced RISC Architecture
– 130 Powerful Instructions – Most Single Clock Cycle Execution
– 32 x 8 General Purpose Working Registers + Peripheral Control Registers
– Fully Static Operation
– Up to 16 MIPS Throughput at 16 MHz
– On-chip 2-cycle Multiplier
• High Endurance Non-volatile Memory segments
– 64K Bytes of In-System Reprogrammable Flash program memory
– 2K Bytes EEPROM
– 4K Bytes Internal SRAM
– Write/Erase Cycles: 10,000 Flash/100,000 EEPROM
– Data retention: 20 years at 85°C/100 years at 25°C
– Optional Boot Code Section with Independent Lock Bits
• In-System Programming by On-chip Boot Program
• True Read-While-Write Operation
– Up to 64K Bytes Optional External Memory Space
– Programming Lock for Software Security
– SPI Interface for In-System Programming
• JTAG (IEEE std. 1149.1 Compliant) Interface
– Boundary-scan Capabilities According to the JTAG Standard
– Extensive On-chip Debug Support
– Programming of Flash, EEPROM, Fuses, and Lock Bits through the JTAG Interface
• Peripheral Features
– Two 8-bit Timer/Counters with Separate Prescalers and Compare Modes
– Two Expanded 16-bit Timer/Counters with Separate Prescaler, Compare Mode, and
Capture Mode
– Real Time Counter with Separate Oscillator
– Two 8-bit PWM Channels
– 6 PWM Channels with Programmable Resolution from 1 to 16 Bits
– 8-channel, 10-bit ADC
• 8 Single-ended Channels
• 7 Differential Channels
• 2 Differential Channels with Programmable Gain (1x, 10x, 200x)
– Byte-oriented Two-wire Serial Interface
– Dual Programmable Serial USARTs
– Master/Slave SPI Serial Interface
– Programmable Watchdog Timer with On-chip Oscillator
– On-chip Analog Comparator
• Special Microcontroller Features
– Power-on Reset and Programmable Brown-out Detection
– Internal Calibrated RC Oscillator
– External and Internal Interrupt Sources
– Six Sleep Modes: Idle, ADC Noise Reduction, Power-save, Power-down, Standby
and Extended Standby
– Software Selectable Clock Frequency
– ATmega103 Compatibility Mode Selected by a Fuse
– Global Pull-up Disable
• I/O and Packages
– 53 Programmable I/O Lines
– 64-lead TQFP and 64-pad QFN/MLF
• Operating Voltages
– 2.7 - 5.5V for ATmega64A
• Speed Grades
– 0 - 16 MHz for ATmega64A
®
8-bit Microcontroller
(1)
8-bit
Microcontroller
with 64K Bytes
In-System
Programmable
Flash
ATmega64A
8160C–AVR–07/09
Page 2

1. Pin Configuration
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
48
47
46
45
44
43
42
41
40
39
38
37
36
35
34
33
PEN
RXD0/(PDI) PE0
(TXD0/PDO) PE1
(XCK0/AIN0) PE2
(OC3A/AIN1) PE3
(OC3B/INT4) PE4
(OC3C/INT5) PE5
(T3/INT6) PE6
(ICP3/INT7) PE7
(SS) PB0
(SCK) PB1
(MOSI) PB2
(MISO) PB3
(OC0) PB4
(OC1A) PB5
(OC1B) PB6
PA3 (AD3)
PA4 (AD4)
PA5 (AD5)
PA6 (AD6)
PA7 (AD7)
PG2(ALE)
PC7 (A15)
PC6 (A14)
PC5 (A13)
PC4 (A12)
PC3 (A11)
PC2 (A10
PC1 (A9)
PC0 (A8)
PG1(RD)
PG0(WR)
646362616059585756555453525150
49
171819202122232425262728293031
32
(OC2/OC1C) PB7
TOSC2/PG3
TOSC1/PG4
RESET
VCC
GND
XTAL2
XTAL1
(SCL/INT0) PD0
(SDA/INT1) PD1
(RXD1/INT2) PD2
(TXD1/INT3) PD3
(ICP1) PD4
(XCK1) PD5
(T1) PD6
(T2) PD7
AVCC
GND
AREF
PF0 (ADC0)
PF1 (ADC1)
PF2 (ADC2)
PF3 (ADC3)
PF4 (ADC4/TCK)
PF5 (ADC5/TMS)
PF6 (ADC6/TDO)
PF7 (ADC7/TDI)
GND
VCC
PA0 (AD0)
PA1 (AD1)
PA2 (AD2)
TQFP/MLF
Figure 1-1. Pinout ATmega64A
ATmega64A
Note: The bottom pad under the QFN/MLF package should be soldered to ground.
8160C–AVR–07/09
2
Page 3

2. Overview
PROGRAM
COUNTER
INTERNAL
OSCILLATOR
WATCHDOG
TIMER
STACK
POINTER
PROGRAM
FLASH
MCU CONTROL
REGISTER
SRAM
GENERAL
PURPOSE
REGISTERS
INSTRUCTION
REGISTER
TIMER/
COUNTERS
INSTRUCTION
DECODER
DATADIR.
REG. PORTB
DATADIR.
REG. PORTE
DATADIR.
REG. PORTA
DATADIR.
REG. PORTD
DATAREGISTER
PORTB
DATAREGISTER
PORTE
DATAREGISTER
PORTA
DATAREGISTER
PORTD
TIMING AND
CONTROL
OSCILLATOR
OSCILLATOR
INTERRUPT
UNIT
EEPROM
SPI
USART0
STATUS
REGISTER
Z
Y
X
ALU
PORTB DRIVERS
PORTE DRIVERS
PORTA DRIVERS
PORTF DRIVERS
PORTD DRIVERS
PORTC DRIVERS
PB0 - PB7PE0 - PE7
PA0 - PA7PF0 - PF7
RESET
VCC
GND
AREF
XTAL1
XTAL2
CONTROL
LINES
+
-
ANALOG
COMPARATOR
PC0 - PC7
8-BIT DATA BUS
AVC C
USART1
CALIB. OSC
DATADIR.
REG. PORTC
DATAREGISTER
PORTC
ON-CHIP DEBUG
JTAG TAP
PROGRAMMING
LOGIC
PEN
BOUNDARY-
SCAN
DATADIR.
REG. PORTF
DATAREGISTER
PORTF
ADC
PD0 - PD7
DATADIR.
REG. PORTG
DATAREG.
PORTG
PORTG DRIVERS
PG0 - PG4
2-WIRE SERIAL
INTERFACE
The ATmega64A is a low-power CMOS 8-bit microcontroller based on the AVR enhanced RISC
architecture. By executing powerful instructions in a single clock cycle, the ATmega64A achieves
throughputs approaching 1 MIPS per MHz, allowing the system designer to optimize power consumption versus processing speed.
2.1 Block Diagram
Figure 2-1. Block Diagram
ATmega64A
8160C–AVR–07/09
The AVR core combines a rich instruction set with 32 general purpose working registers. All the
32 registers are directly connected to the Arithmetic Logic Unit (ALU), allowing two independent
registers to be accessed in one single instruction executed in one clock cycle. The resulting
architecture is more code efficient while achieving throughputs up to ten times faster than conventional CISC microcontrollers.
The ATmega64A provides the following features: 64K bytes of In-System Programmable Flash
with Read-While-Write capabilities, 2K bytes EEPROM, 4K bytes SRAM, 53 general purpose I/O
3
Page 4

ATmega64A
lines, 32 general purpose working registers, Real Time Counter (RTC), four flexible Timer/Counters with compare modes and PWM, two USARTs, a byte oriented Two-wire Serial Interface, an
8-channel, 10-bit ADC with optional differential input stage with programmable gain, programmable Watchdog Timer with internal Oscillator, an SPI serial port, IEEE std. 1149.1 compliant
JTAG test interface, also used for accessing the On-chip Debug system and programming, and
six software selectable power saving modes. The Idle mode stops the CPU while allowing the
SRAM, Timer/Counters, SPI port, and interrupt system to continue functioning. The Power-down
mode saves the register contents but freezes the Oscillator, disabling all other chip functions
until the next interrupt or Hardware Reset. In Power-save mode, the asynchronous timer continues to run, allowing the user to maintain a timer base while the rest of the device is sleeping.
The ADC Noise Reduction mode stops the CPU and all I/O modules except asynchronous timer
and ADC, to minimize switching noise during ADC conversions. In Standby mode, the crystal/resonator Oscillator is running while the rest of the device is sleeping. This allows very fast
start-up combined with low power consumption. In Extended Standby mode, both the main
Oscillator and the asynchronous timer continue to run.
The device is manufactured using Atmel’s high-density non-volatile memory technology. The
On-chip ISP Flash allows the program memory to be reprogrammed In-System through an SPI
serial interface, by a conventional non-volatile memory programmer, or by an On-chip Boot program running on the AVR core. The Boot Program can use any interface to download the
Application Program in the Application Flash memory. Software in the Boot Flash section will
continue to run while the Application Flash section is updated, providing true Read-While-Write
operation. By combining an 8-bit RISC CPU with In-System Self-Programmable Flash on a
monolithic chip, the Atmel ATmega64A is a powerful microcontroller that provides a highly-flexible and cost-effective solution to many embedded control applications.
The ATmega64A AVR is supported with a full suite of program and system development tools
including: C compilers, macro assemblers, program debugger/simulators, In-Circuit Emulators,
and evaluation kits.
2.2 ATmega103 and ATmega64A Compatibility
The ATmega64A is a highly complex microcontroller where the number of I/O locations supersedes the 64 I/O location reserved in the AVR instruction set. To ensure backward compatibility
with the ATmega103, all I/O locations present in ATmega103 have the same location in
ATmega64A. Most additional I/O locations are added in an Extended I/O space starting from
0x60 to 0xFF (i.e., in the ATmega103 internal RAM space). These location can be reached by
using LD/LDS/LDD and ST/STS/STD instructions only, not by using IN and OUT instructions.
The relocation of the internal RAM space may still be a problem for ATmega103 users. Also, the
increased number of Interrupt Vectors might be a problem if the code uses absolute addresses.
To solve these problems, an ATmega103 compatibility mode can be selected by programming
the fuse M103C. In this mode, none of the functions in the Extended I/O space are in use, so the
internal RAM is located as in ATmega103. Also, the extended Interrupt Vectors are removed.
The ATmega64A is 100% pin compatible with ATmega103, and can replace the ATmega103 on
current printed circuit boards. The application notes “Replacing ATmega103 by ATmega128”
and “Migration between ATmega64 and ATmega128” describes what the user should be aware
of replacing the ATmega103 by an ATmega128 or ATmega64.
8160C–AVR–07/09
4
Page 5

2.2.1 ATmega103 Compatibility Mode
By programming the M103C Fuse, the ATmega64A will be compatible with the ATmega103
regards to RAM, I/O pins and Interrupt Vectors as described above. However, some new features in ATmega64A are not available in this compatibility mode, these features are listed below:
• One USART instead of two, asynchronous mode only. Only the eight least significant bits of
the Baud Rate Register is available.
• One 16 bits Timer/Counter with two compare registers instead of two 16 bits Timer/Counters
with three compare registers.
• Two-wire serial interface is not supported.
• Port G serves alternate functions only (not a general I/O port).
• Port F serves as digital input only in addition to analog input to the ADC.
• Boot Loader capabilities is not supported.
• It is not possible to adjust the frequency of the internal calibrated RC Oscillator.
• The External Memory Interface can not release any Address pins for general I/O, neither
configure different wait states to different External Memory Address sections.
• Only EXTRF and PORF exist in the MCUCSR Register.
• No timed sequence is required for Watchdog Timeout change.
• Only low-level external interrupts can be used on four of the eight External Interrupt sources.
• Port C is output only.
• USART has no FIFO buffer, so Data OverRun comes earlier.
• The user must have set unused I/O bits to 0 in ATmega103 programs.
ATmega64A
2.3 Pin Descriptions
2.3.1 VCC
Digital supply voltage.
2.3.2 GND
Ground.
2.3.3 Port A (PA7:PA0)
Port A is an 8-bit bi-directional I/O port with internal pull-up resistors (selected for each bit). The
Port A output buffers have symmetrical drive characteristics with both high sink and source
capability. As inputs, Port A pins that are externally pulled low will source current if the pull-up
resistors are activated. The Port A pins are tri-stated when a reset condition becomes active,
even if the clock is not running.
Port A also serves the functions of various special features of the ATmega64A as listed on page
75.
2.3.4 Port B (PB7:PB0)
Port B is an 8-bit bi-directional I/O port with internal pull-up resistors (selected for each bit). The
Port B output buffers have symmetrical drive characteristics with both high sink and source
capability. As inputs, Port B pins that are externally pulled low will source current if the pull-up
resistors are activated. The Port B pins are tri-stated when a reset condition becomes active,
even if the clock is not running.
8160C–AVR–07/09
5
Page 6

Port B also serves the functions of various special features of the ATmega64A as listed on page
76.
2.3.5 Port C (PC7:PC0)
Port C is an 8-bit bi-directional I/O port with internal pull-up resistors (selected for each bit). The
Port C output buffers have symmetrical drive characteristics with both high sink and source
capability. As inputs, Port C pins that are externally pulled low will source current if the pull-up
resistors are activated. The Port C pins are tri-stated when a reset condition becomes active,
even if the clock is not running.
Port C also serves the functions of special features of the ATmega64A as listed on page 79. In
ATmega103 compatibility mode, Port C is output only, and the port C pins are not tri-stated
when a reset condition becomes active.
2.3.6 Port D (PD7:PD0)
Port D is an 8-bit bi-directional I/O port with internal pull-up resistors (selected for each bit). The
Port D output buffers have symmetrical drive characteristics with both high sink and source
capability. As inputs, Port D pins that are externally pulled low will source current if the pull-up
resistors are activated. The Port D pins are tri-stated when a reset condition becomes active,
even if the clock is not running.
ATmega64A
Port D also serves the functions of various special features of the ATmega64A as listed on page
80.
2.3.7 Port E (PE7:PE0)
Port E is an 8-bit bi-directional I/O port with internal pull-up resistors (selected for each bit). The
Port E output buffers have symmetrical drive characteristics with both high sink and source
capability. As inputs, Port E pins that are externally pulled low will source current if the pull-up
resistors are activated. The Port E pins are tri-stated when a reset condition becomes active,
even if the clock is not running.
Port E also serves the functions of various special features of the ATmega64A as listed on page
83.
2.3.8 Port F (PF7:PF0)
Port F serves as the analog inputs to the A/D Converter.
Port F also serves as an 8-bit bi-directional I/O port, if the A/D Converter is not used. Port pins
can provide internal pull-up resistors (selected for each bit). The Port F output buffers have symmetrical drive characteristics with both high sink and source capability. As inputs, Port F pins
that are externally pulled low will source current if the pull-up resistors are activated. The Port F
pins are tri-stated when a reset condition becomes active, even if the clock is not running. If the
JTAG interface is enabled, the pull-up resistors on pins PF7(TDI), PF5(TMS) and PF4(TCK) will
be activated even if a reset occurs.
8160C–AVR–07/09
The TDO pin is tri-stated unless TAP states that shift out data are entered.
Port F also serves the functions of the JTAG interface.
In ATmega103 compatibility mode, Port F is an input port only.
6
Page 7

2.3.9 Port G (PG4:PG0)
Port G is a 5-bit bi-directional I/O port with internal pull-up resistors (selected for each bit). The
Port G output buffers have symmetrical drive characteristics with both high sink and source
capability. As inputs, Port G pins that are externally pulled low will source current if the pull-up
resistors are activated. The Port G pins are tri-stated when a reset condition becomes active,
even if the clock is not running.
Port G also serves the functions of various special features.
In ATmega103 compatibility mode, these pins only serves as strobes signals to the external
memory as well as input to the 32 kHz Oscillator, and the pins are initialized to PG0 = 1,
PG1 = 1, and PG2 = 0 asynchronously when a reset condition becomes active, even if the clock
is not running. PG3 and PG4 are Oscillator pins.
2.3.10 RESET
Reset input. A low level on this pin for longer than the minimum pulse length will generate a
reset, even if the clock is not running. The minimum pulse length is given in Table 28-3 on page
330. Shorter pulses are not guaranteed to generate a reset.
2.3.11 XTAL1
Input to the inverting Oscillator amplifier and input to the internal clock operating circuit.
ATmega64A
2.3.12 XTAL2
2.3.13 AVCC
2.3.14 AREF
2.3.15 PEN
3. Resources
Output from the inverting Oscillator amplifier.
AVCC is the supply voltage pin for Port F and the A/D Converter. It should be externally connected to V
through a low-pass filter.
AREF is the analog reference pin for the A/D Converter.
This is a programming enable pin for the SPI Serial Programming mode. By holding this pin low
during a Power-on Reset, the device will enter the SPI Serial Programming mode. PEN is internally pulled high. The pullup is shown in Figure 10-1 on page 52 and its value is given in Section
28.2 “DC Characteristics” on page 327. PEN
A comprehensive set of development tools, application notes and datasheetsare available for
download on http://www.atmel.com/avr.
Note: 1.
, even if the ADC is not used. If the ADC is used, it should be connected to V
CC
has no function during normal operation.
CC
4. Data Retention
8160C–AVR–07/09
Reliability Qualification results show that the projected data retention failure rate is much less
than 1 PPM over 20 years at 85°C or 100 years at 25°C.
7
Page 8
5. About Code Examples
This datasheet contains simple code examples that briefly show how to use various parts of the
device. These code examples assume that the part specific header file is included before compilation. Be aware that not all C compiler vendors include bit definitions in the header files and
interrupt handling in C is compiler dependent. Please confirm with the C compiler documentation
for more details.
For I/O Registers located in extended I/O map, “IN”, “OUT”, “SBIS”, “SBIC”, “CBI”, and “SBI”
instructions must be replaced with instructions that allow access to extended I/O. Typically
“LDS” and “STS” combined with “SBRS”, “SBRC”, “SBR”, and “CBR”.
ATmega64A
8160C–AVR–07/09
8
Page 9

6. AVR CPU Core
Flash
Program
Memory
Instruction
Register
Instruction
Decoder
Program
Counter
Control Lines
32 x 8
General
Purpose
Registrers
ALU
Status
and Control
I/O Lines
EEPROM
Data Bus 8-bit
Data
SRAM
Direct Addressing
Indirect Addressing
Interrupt
Unit
SPI
Unit
Watchdog
Timer
Analog
Comparator
I/O Module 2
I/O Module1
I/O Module n
6.1 Overview
ATmega64A
This section discusses the AVR core architecture in general. The main function of the CPU core
is to ensure correct program execution. The CPU must therefore be able to access memories,
perform calculations, control peripherals, and handle interrupts.
Figure 6-1. Block Diagram of the AVR MCU Architecture
8160C–AVR–07/09
In order to maximize performance and parallelism, the AVR uses a Harvard architecture – with
separate memories and buses for program and data. Instructions in the program memory are
executed with a single level pipelining. While one instruction is being executed, the next instruction is pre-fetched from the program memory. This concept enables instructions to be executed
in every clock cycle. The program memory is In-System Reprogrammable Flash memory.
The fast-access Register File contains 32 x 8-bit general purpose working registers with a single
clock cycle access time. This allows single-cycle Arithmetic Logic Unit (ALU) operation. In a typ-
9
Page 10
ATmega64A
ical ALU operation, two operands are output from the Register File, the operation is executed,
and the result is stored back in the Register File – in one clock cycle.
Six of the 32 registers can be used as three 16-bit indirect address register pointers for Data
Space addressing – enabling efficient address calculations. One of the these address pointers
can also be used as an address pointer for look up tables in Flash program memory. These
added function registers are the 16-bit X-, Y-, and Z-register, described later in this section.
The ALU supports arithmetic and logic operations between registers or between a constant and
a register. Single register operations can also be executed in the ALU. After an arithmetic operation, the Status Register is updated to reflect information about the result of the operation.
Program flow is provided by conditional and unconditional jump and call instructions, able to
directly address the whole address space. Most AVR instructions have a single 16-bit word format. Every program memory address contains a 16- or 32-bit instruction.
Program Flash memory space is divided in two sections, the Boot program section and the
Application program section. Both sections have dedicated Lock bits for write and read/write
protection. The SPM instruction that writes into the Application Flash memory section must
reside in the Boot program section.
During interrupts and subroutine calls, the return address Program Counter (PC) is stored on the
Stack. The Stack is effectively allocated in the general data SRAM, and consequently the Stack
size is only limited by the total SRAM size and the usage of the SRAM. All user programs must
initialize the SP in the reset routine (before subroutines or interrupts are executed). The Stack
Pointer SP is read/write accessible in the I/O space. The data SRAM can easily be accessed
through the five different addressing modes supported in the AVR architecture.
The memory spaces in the AVR architecture are all linear and regular memory maps.
A flexible interrupt module has its control registers in the I/O space with an additional Global
Interrupt Enable bit in the Status Register. All interrupts have a separate Interrupt Vector in the
Interrupt Vector table. The interrupts have priority in accordance with their Interrupt Vector position. The lower the Interrupt Vector address, the higher the priority.
The I/O memory space contains 64 addresses which can be accessed directly, or as the Data
Space locations following those of the Register File, 0x20 - 0x5F. In addition, the ATmega64A
has Extended I/O space from 0x60 - 0xFF in SRAM where only the ST/STS/STD and
LD/LDS/LDD instructions can be used.
6.2 ALU – Arithmetic Logic Unit
The high-performance AVR ALU operates in direct connection with all the 32 general purpose
working registers. Within a single clock cycle, arithmetic operations between general purpose
registers or between a register and an immediate are executed. The ALU operations are divided
into three main categories – arithmetic, logical, and bit-functions. Some implementations of the
architecture also provide a powerful multiplier supporting both signed/unsigned multiplication
and fractional format. See the “Instruction Set” section for a detailed description.
6.3 Status Register
The Status Register contains information about the result of the most recently executed arithmetic instruction. This information can be used for altering program flow in order to perform
conditional operations. Note that the Status Register is updated after all ALU operations, as
8160C–AVR–07/09
10
Page 11
specified in the Instruction Set Reference. This will in many cases remove the need for using the
dedicated compare instructions, resulting in faster and more compact code.
The Status Register is not automatically stored when entering an interrupt routine and restored
when returning from an interrupt. This must be handled by software.
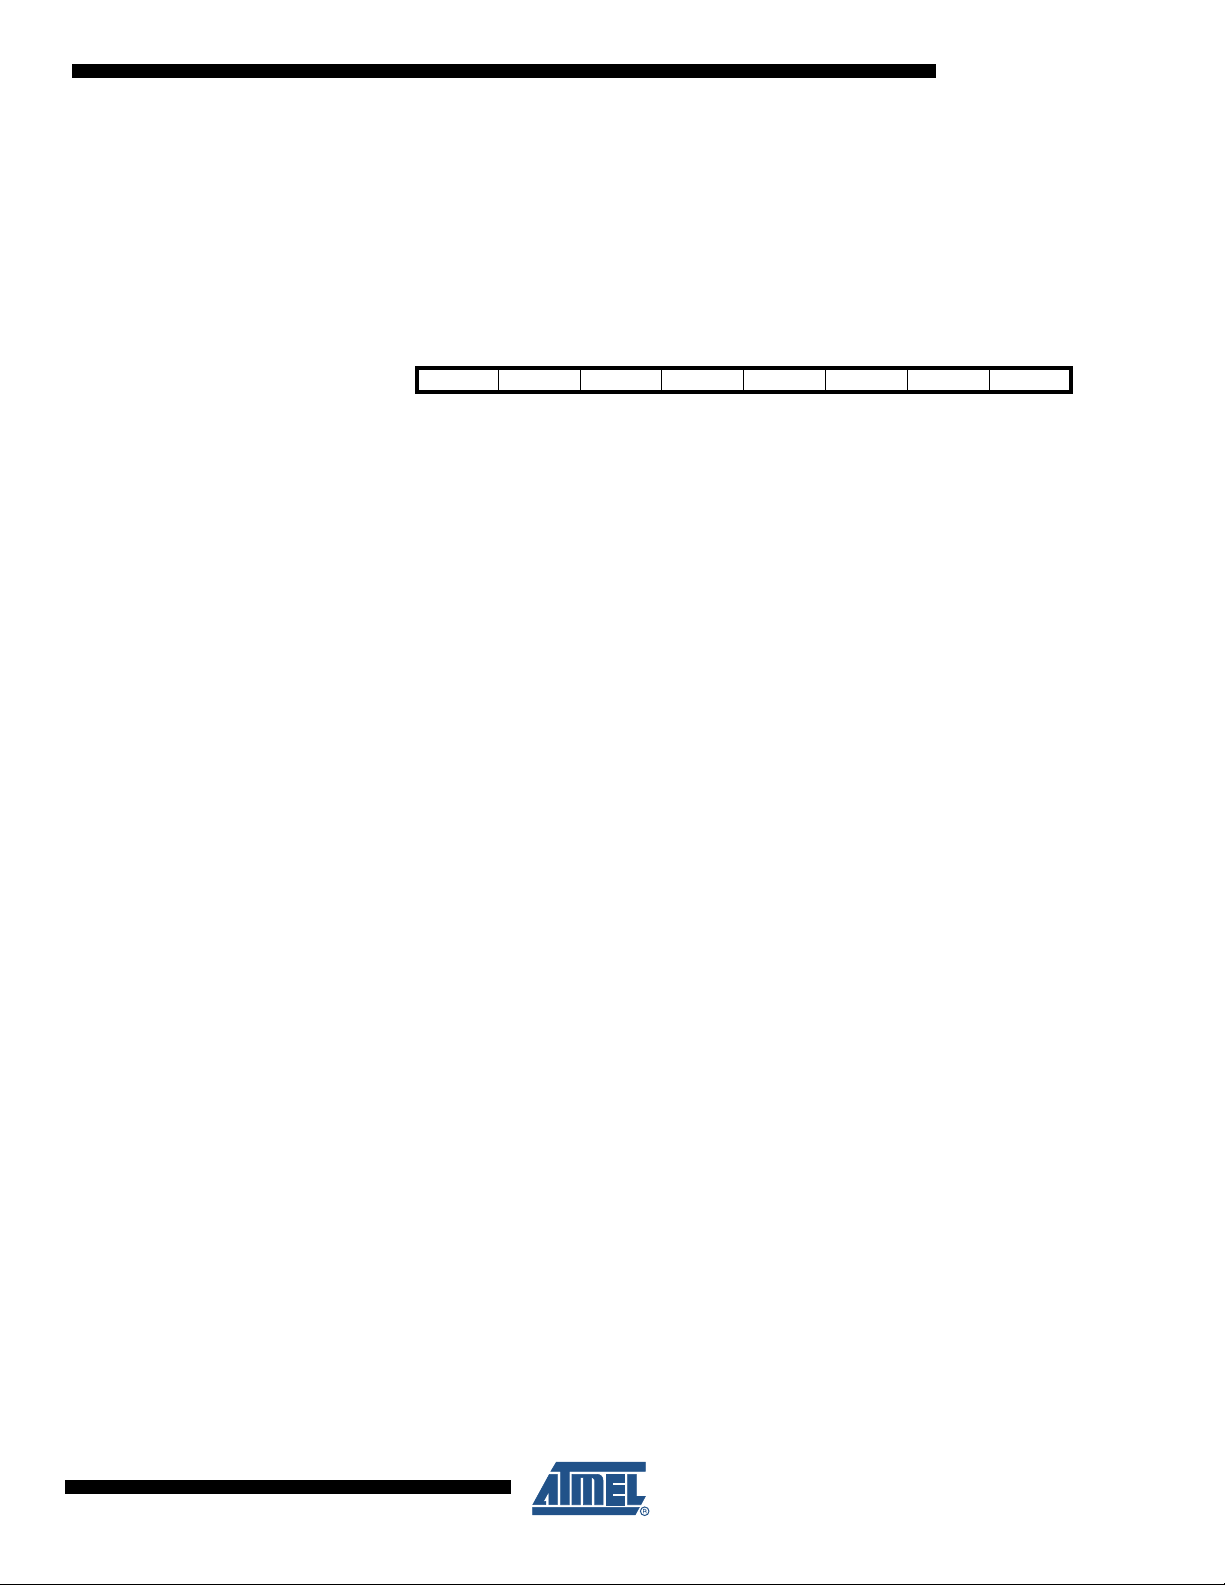
6.3.1 SREG – AVR Status Register
Bit 76543210
0x3F (0x5F) I T H S V N Z C SREG
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
• Bit 7 – I: Global Interrupt Enable
The Global Interrupt Enable bit must be set for the interrupts to be enabled. The individual interrupt enable control is then performed in separate control registers. If the Global Interrupt Enable
Register is cleared, none of the interrupts are enabled independent of the individual interrupt
enable settings. The I-bit is cleared by hardware after an interrupt has occurred, and is set by
the RETI instruction to enable subsequent interrupts. The I-bit can also be set and cleared in
software with the SEI and CLI instructions, as described in the instruction set reference.
ATmega64A
• Bit 6 – T: Bit Copy Storage
The Bit Copy instructions BLD (Bit LoaD) and BST (Bit STore) use the T-bit as source or destination for the operated bit. A bit from a register in the Register File can be copied into T by the
BST instruction, and a bit in T can be copied into a bit in a register in the Register File by the
BLD instruction.
• Bit 5 – H: Half Carry Flag
The Half Carry Flag H indicates a Half Carry in some arithmetic operations. Half Carry is useful
in BCD arithmetic. See the “Instruction Set Description” for detailed information.
• Bit 4 – S: Sign Bit, S = N
⊕ V
The S-bit is always an exclusive or between the Negative Flag N and the Two’s Complement
Overflow Flag V. See the “Instruction Set Description” for detailed information.
• Bit 3 – V: Two’s Complement Overflow Flag
The Two’s Complement Overflow Flag V supports two’s complement arithmetics. See the
“Instruction Set Description” for detailed information.
• Bit 2 – N: Negative Flag
The Negative Flag N indicates a negative result in an arithmetic or logic operation. See the
“Instruction Set Description” for detailed information.
8160C–AVR–07/09
• Bit 1 – Z: Zero Flag
The Zero Flag Z indicates a zero result in an arithmetic or logic operation. See the “Instruction
Set Description” for detailed information.
• Bit 0 – C: Carry Flag
The Carry Flag C indicates a carry in an arithmetic or logic operation. See the “Instruction Set
Description” for detailed information.
11
Page 12
6.3.2 General Purpose Register File
The Register File is optimized for the AVR Enhanced RISC instruction set. In order to achieve
the required performance and flexibility, the following input/output schemes are supported by the
Register File:
• One 8-bit output operand and one 8-bit result input.
• Two 8-bit output operands and one 8-bit result input.
• Two 8-bit output operands and one 16-bit result input.
• One 16-bit output operand and one 16-bit result input.
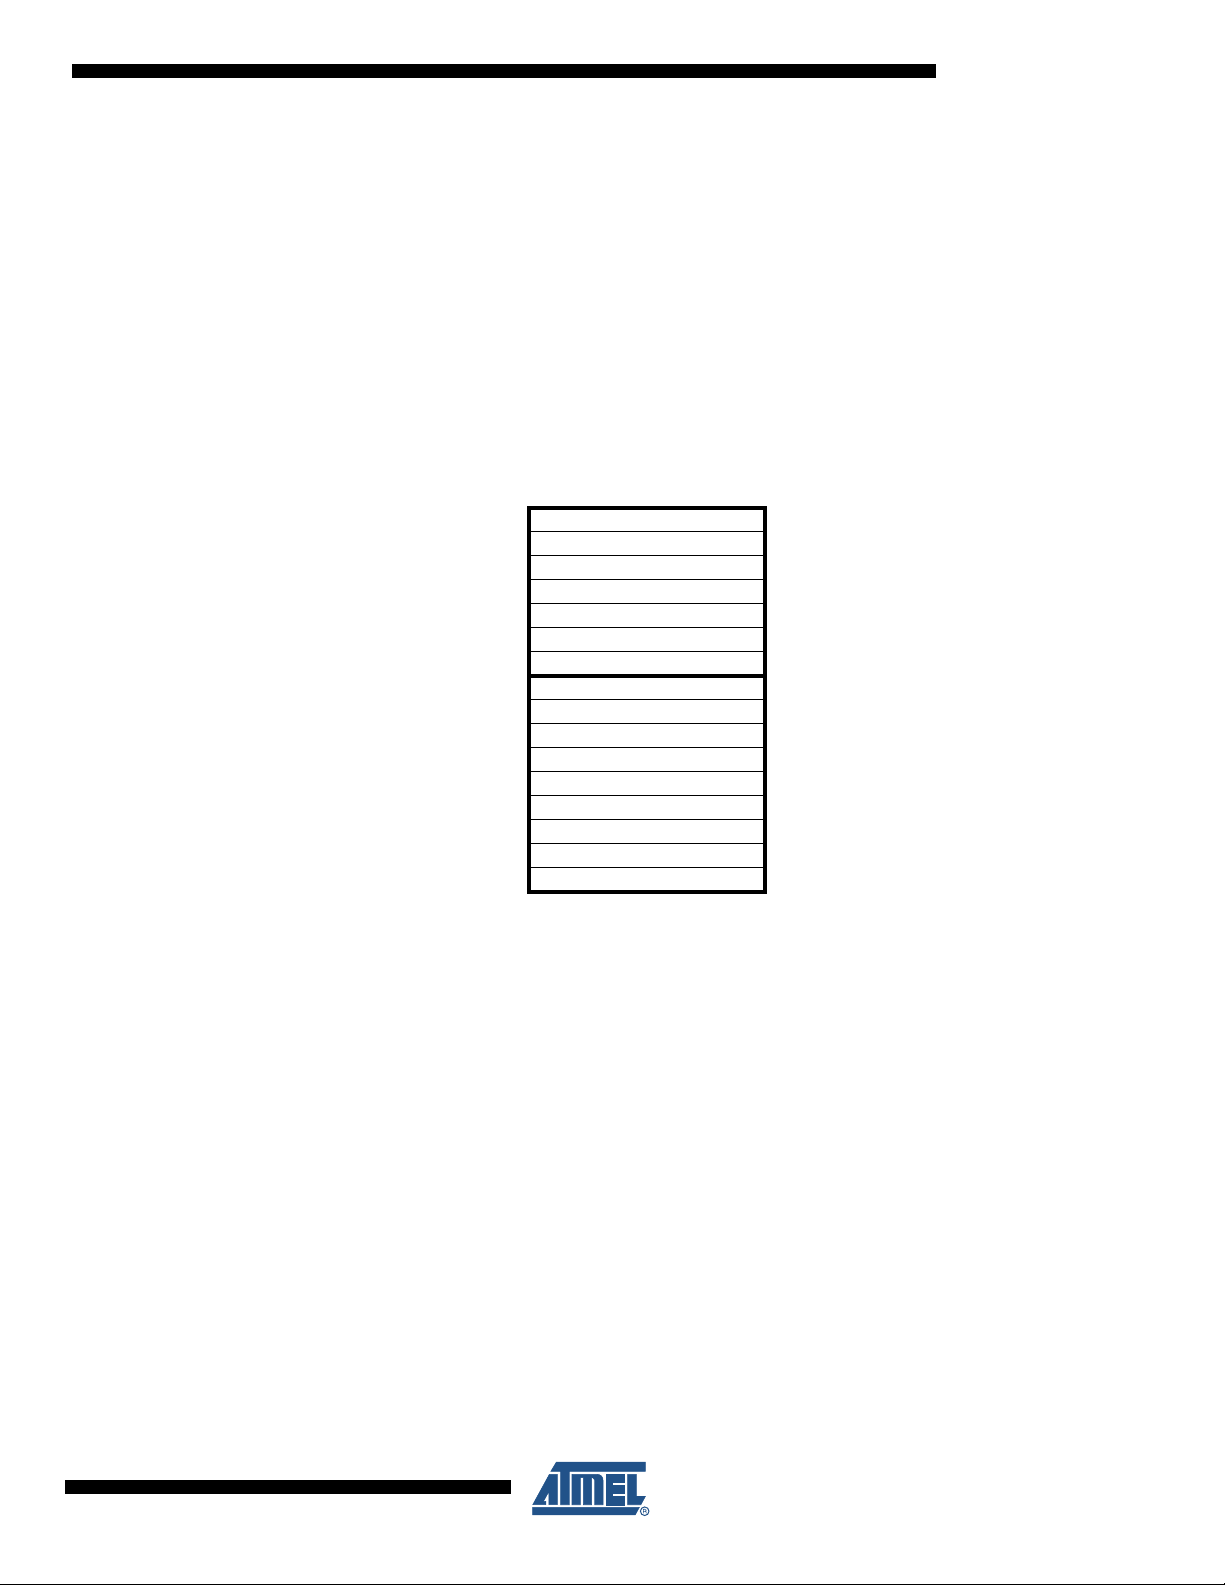
Figure 6-2 shows the structure of the 32 general purpose working registers in the CPU.
Figure 6-2. AVR CPU General Purpose Working Registers
General R14 0x0E
Purpose R15 0x0F
Working R16 0x10
Registers R17 0x11
ATmega64A
7 0 Addr.
R0 0x00
R1 0x01
R2 0x02
…
R13 0x0D
…
R26 0x1A X-register Low Byte
R27 0x1B X-register High Byte
R28 0x1C Y-register Low Byte
R29 0x1D Y-register High Byte
R30 0x1E Z-register Low Byte
R31 0x1F Z-register High Byte
Most of the instructions operating on the Register File have direct access to all registers, and
most of them are single cycle instructions.
As shown in Figure 6-2, each register is also assigned a data memory address, mapping them
directly into the first 32 locations of the user data space. Although not being physically implemented as SRAM locations, this memory organization provides great flexibility in access of the
registers, as the X-, Y-, and Z-pointer registers can be set to index any register in the file.
6.3.3 X-, Y-, and Z-register
The registers R26:R31 have some added functions to their general purpose usage. These registers are 16-bit address pointers for indirect addressing of the data space. The three indirect
address registers X, Y, and Z are defined as described in Figure 6-3.
8160C–AVR–07/09
12
Page 13
6.4 Stack Pointer
ATmega64A
Figure 6-3. The X-, Y-, and Z-Registers
15 XH XL 0
X - register 7 0 7 0
R27 (0x1B) R26 (0x1A)
15 YH YL 0
Y - register 7 0 7 0
R29 (0x1D) R28 (0x1C)
15 ZH ZL 0
Z - register 7 0 7 0
R31 (0x1F) R30 (0x1E)
In the different addressing modes these address registers have functions as fixed displacement,
automatic increment, and automatic decrement (see the Instruction Set Reference for details).
The Stack is mainly used for storing temporary data, for storing local variables and for storing
return addresses after interrupts and subroutine calls. The Stack Pointer Register always points
to the top of the Stack. Note that the Stack is implemented as growing from higher memory locations to lower memory locations. This implies that a Stack PUSH command decreases the Stack
Pointer. If software reads the Program Counter from the Stack after a call or an interrupt, unused
bits (bit 15) should be masked out.
The Stack Pointer points to the data SRAM Stack area where the subroutine and interrupt
Stacks are located. This Stack space in the data SRAM must be defined by the program before
any subroutine calls are executed or interrupts are enabled. The Stack Pointer must be set to
point above 0x60. The Stack Pointer is decremented by one when data is pushed onto the Stack
with the PUSH instruction, and it is decremented by two when the return address is pushed onto
the Stack with subroutine call or interrupt. The Stack Pointer is incremented by one when data is
popped from the Stack with the POP instruction, and it is incremented by two when data is
popped from the Stack with return from subroutine RET or return from interrupt RETI.
The AVR Stack Pointer is implemented as two 8-bit registers in the I/O space. The number of
bits actually used is implementation dependent. Note that the data space in some implementations of the AVR architecture is so small that only SPL is needed. In this case, the SPH Register
will not be present.
Bit 151413121110 9 8
0x3E (0x5E) SP15 SP14 SP13 SP12 SP11 SP10 SP9 SP8 SPH
0x3D (0x5D) SP7 SP6 SP5 SP4 SP3 SP2 SP1 SP0 SPL
76543210
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
00000000
6.5 Instruction Execution Timing
This section describes the general access timing concepts for instruction execution. The AVR
CPU is driven by the CPU clock clk
chip. No internal clock division is used.
, directly generated from the selected clock source for the
CPU
8160C–AVR–07/09
13
Page 14

ATmega64A
clk
1st Instruction Fetch
1st Instruction Execute
2nd Instruction Fetch
2nd Instruction Execute
3rd Instruction Fetch
3rd Instruction Execute
4th Instruction Fetch
T1 T2 T3 T4
CPU
Total Execution Time
Register Operands Fetch
ALU Operation Execute
Result Write Back
T1 T2 T3 T4
clk
CPU
Figure 6-4 shows the parallel instruction fetches and instruction executions enabled by the Har-
vard architecture and the fast-access Register File concept. This is the basic pipelining concept
to obtain up to 1 MIPS per MHz with the corresponding unique results for functions per cost,
functions per clocks, and functions per power-unit.
Figure 6-4. The Parallel Instruction Fetches and Instruction Executions
Figure 6-5 shows the internal timing concept for the Register File. In a single clock cycle an ALU
operation using two register operands is executed, and the result is stored back to the destination register.
6.6 Reset and Interrupt Handling
8160C–AVR–07/09
Figure 6-5. Single Cycle ALU Operation
The AVR provides several different interrupt sources. These interrupts and the separate Reset
Vector each have a separate program vector in the program memory space. All interrupts are
assigned individual enable bits which must be written logic one together with the Global Interrupt
Enable bit in the Status Register in order to enable the interrupt. Depending on the Program
Counter value, interrupts may be automatically disabled when Boot Lock bits BLB02 or BLB12
are programmed. This feature improves software security. See the section “Memory Program-
ming” on page 295 for details.
The lowest addresses in the program memory space are by default defined as the Reset and
Interrupt Vectors. The complete list of vectors is shown in “Interrupts” on page 60. The list also
determines the priority levels of the different interrupts. The lower the address the higher is the
priority level. RESET has the highest priority, and next is INT0 – the External Interrupt Request
0. The Interrupt Vectors can be moved to the start of the Boot Flash section by setting the IVSEL
bit in the MCU Control Register (MCUCR). Refer to “Interrupts” on page 60 for more information.
The Reset Vector can also be moved to the start of the Boot Flash section by programming the
14
Page 15

ATmega64A
BOOTRST Fuse, see “Boot Loader Support – Read-While-Write Self-programming” on page
281.
When an interrupt occurs, the Global Interrupt Enable I-bit is cleared and all interrupts are disabled. The user software can write logic one to the I-bit to enable nested interrupts. All enabled
interrupts can then interrupt the current interrupt routine. The I-bit is automatically set when a
Return from Interrupt instruction – RETI – is executed.
There are basically two types of interrupts. The first type is triggered by an event that sets the
interrupt flag. For these interrupts, the Program Counter is vectored to the actual Interrupt Vector
in order to execute the interrupt handling routine, and hardware clears the corresponding interrupt flag. Interrupt flags can also be cleared by writing a logic one to the flag bit position(s) to be
cleared. If an interrupt condition occurs while the corresponding interrupt enable bit is cleared,
the interrupt flag will be set and remembered until the interrupt is enabled, or the flag is cleared
by software. Similarly, if one or more interrupt conditions occur while the Global Interrupt Enable
bit is cleared, the corresponding interrupt flag(s) will be set and remembered until the Global
Interrupt Enable bit is set, and will then be executed by order of priority.
The second type of interrupts will trigger as long as the interrupt condition is present. These
interrupts do not necessarily have interrupt flags. If the interrupt condition disappears before the
interrupt is enabled, the interrupt will not be triggered.
When the AVR exits from an interrupt, it will always return to the main program and execute one
more instruction before any pending interrupt is served.
Note that the Status Register is not automatically stored when entering an interrupt routine, nor
restored when returning from an interrupt routine. This must be handled by software.
When using the CLI instruction to disable interrupts, the interrupts will be immediately disabled.
No interrupt will be executed after the CLI instruction, even if it occurs simultaneously with the
CLI instruction. The following example shows how this can be used to avoid interrupts during the
timed EEPROM write sequence.
Assembly Code Example
in r16, SREG ; store SREG value
cli ; disable interrupts during timed sequence
sbi EECR, EEMWE ; start EEPROM write
sbi EECR, EEWE
out SREG, r16 ; restore SREG value (I-bit)
C Code Example
char cSREG;
cSREG = SREG; /* store SREG value */
/* disable interrupts during timed sequence */
_CLI();
EECR |= (1<<EEMWE); /* start EEPROM write */
EECR |= (1<<EEWE);
SREG = cSREG; /* restore SREG value (I-bit) */
8160C–AVR–07/09
15
Page 16

When using the SEI instruction to enable interrupts, the instruction following SEI will be executed before any pending interrupts, as shown in this example.
Assembly Code Example
sei ; set global interrupt enable
sleep ; enter sleep, waiting for interrupt
; note: will enter sleep before any pending
; interrupt(s)
C Code Example
_SEI(); /* set global interrupt enable */
_SLEEP(); /* enter sleep, waiting for interrupt */
/* note: will enter sleep before any pending interrupt(s) */
6.7 Interrupt Response Time
The interrupt execution response for all the enabled AVR interrupts is four clock cycles minimum. After four clock cycles the program vector address for the actual interrupt handling routine
is executed. During this four clock cycle period, the Program Counter is pushed onto the Stack.
The vector is normally a jump to the interrupt routine, and this jump takes three clock cycles. If
an interrupt occurs during execution of a multi-cycle instruction, this instruction is completed
before the interrupt is served. If an interrupt occurs when the MCU is in sleep mode, the interrupt
execution response time is increased by four clock cycles. This increase comes in addition to the
start-up time from the selected sleep mode.
ATmega64A
A return from an interrupt handling routine takes four clock cycles. During these four clock
cycles, the Program Counter (two bytes) is popped back from the Stack, the Stack Pointer is
incremented by two, and the I-bit in SREG is set.
8160C–AVR–07/09
16
Page 17

7. AVR Memories
This section describes the different memories in the ATmega64A. The AVR architecture has two
main memory spaces, the Data Memory and the Program Memory space. In addition, the
ATmega64A features an EEPROM Memory for data storage. All three memory spaces are linear
and regular.
7.1 In-System Reprogrammable Flash Program Memory
The ATmega64A contains 64K bytes On-chip In-System Reprogrammable Flash memory for
program storage. Since all AVR instructions are 16 or 32 bits wide, the Flash is organized as
32K x 16. For software security, the Flash Program memory space is divided into two sections,
Boot Program section and Application Program section.
The Flash memory has an endurance of at least 10,000 write/erase cycles. The ATmega64A
Program Counter (PC) is 15 bits wide, thus addressing the 32K program memory locations. The
operation of Boot Program section and associated Boot Lock bits for software protection are
described in detail in “Boot Loader Support – Read-While-Write Self-programming” on page 281.
“Memory Programming” on page 295 contains a detailed description on Flash programming in
SPI, JTAG, or Parallel Programming mode.
ATmega64A
Constant tables can be allocated within the entire program memory address space (see the LPM
– Load Program Memory instruction description).
Timing diagrams for instruction fetch and execution are presented in “Instruction Execution Tim-
ing” on page 13.
8160C–AVR–07/09
17
Page 18

Figure 7-1. Program Memory Map
$0000
$7FFF
Application Flash Section
Boot Flash Section
ATmega64A
7.2 SRAM Data Memory
The ATmega64A supports two different configurations for the SRAM data memory as listed in
Table 7-1.
Table 7-1. Memory Configurations
Configuration
Normal mode 4096 up to 64K
ATmega103 compatibility mode 4000 up to 64K
Figure 7-2 on page 20 shows how the ATmega64A SRAM Memory is organized.
The ATmega64A is a complex microcontroller with more peripheral units than can be supported
within the 64 locations reserved in the Opcode for the IN and OUT instructions. For the
Extended I/O space from 0x60 - 0xFF in SRAM, only the ST/STS/STD and LD/LDS/LDD instructions can be used. The Extended I/O space does not exist when the ATmega64A is in the
ATmega103 compatibility mode.
The first 4,352 data memory locations address both the Register File, the I/O memory, Extended
I/O memory, and the internal data SRAM. The first 32 locations address the Register File, the
next 64 location the standard I/O memory, then 160 locations of Extended I/O memory, and the
next 4,096 locations address the internal data SRAM.
Internal SRAM
Data Memory
External SRAM
Data Memory
8160C–AVR–07/09
18
Page 19

ATmega64A
In ATmega103 compatibility mode, the first 4,096 data memory locations address both the Register File, the I/O memory and the internal data SRAM. The first 32 locations address the
Register File, the next 64 location the standard I/O memory, and the next 4,000 locations
address the internal data SRAM.
An optional external data SRAM can be used with the ATmega64A. This SRAM will occupy an
area in the remaining address locations in the 64K address space. This area starts at the
address following the internal SRAM. The Register File, I/O, Extended I/O and internal SRAM
occupy the lowest 4,352 bytes in Normal mode, and the lowest 4,096 bytes in the ATmega103
compatibility mode (Extended I/O not present), so when using 64KB (65,536 bytes) of External
memory, 61,184 Bytes of External memory are available in Normal mode, and 61,440 Bytes in
ATmega103 compatibility mode. See “External Memory Interface” on page 23 for details on how
to take advantage of the external memory map.
When the addresses accessing the SRAM memory space exceeds the internal data memory
locations, the external data SRAM is accessed using the same instructions as for the internal
data memory access. When the internal data memories are accessed, the read and write strobe
pins (PG0 and PG1) are inactive during the whole access cycle. External SRAM operation is
enabled by setting the SRE bit in the MCUCR Register.
Accessing external SRAM takes one additional clock cycle per byte compared to access of the
internal SRAM. This means that the commands LD, ST, LDS, STS, LDD, STD, PUSH, and POP
take one additional clock cycle. If the Stack is placed in external SRAM, interrupts, subroutine
calls and returns take three clock cycles extra because the 2-byte Program Counter is pushed
and popped, and external memory access does not take advantage of the internal pipeline
memory access. When external SRAM interface is used with wait state, one-byte external
access takes two, three, or four additional clock cycles for one, two, and three wait states
respectively. Interrupt, subroutine calls and returns will need five, seven, or nine clock cycles
more than specified in the AVR Instruction Set manual for one, two, and three waitstates.
The five different addressing modes for the data memory cover: Direct, Indirect with Displacement, Indirect, Indirect with Pre-decrement, and Indirect with Post-increment. In the Register
File, registers R26 to R31 feature the indirect addressing pointer registers.
The direct addressing reaches the entire data space.
The Indirect with Displacement mode reaches 63 address locations from the base address given
by the Y- or Z-register.
When using register indirect addressing modes with automatic pre-decrement and post-increment, the address registers X, Y, and Z are decremented or incremented.
The 32 general purpose working registers, 64 I/O Registers, 160 extended I/O Registers, and
the 4,096 bytes of internal data SRAM in the ATmega64A are all accessible through all these
addressing modes. The Register File is described in “General Purpose Register File” on page
12.
8160C–AVR–07/09
19
Page 20

Figure 7-2. Data Memory Map
Memory Configuration B
32 Registers
64 I/O Registers
Internal SRAM
(4000 x 8)
$0000 - $001F
$0020 - $005F
$1000
$0FFF
$FFFF
$0060
Data Memory
External SRAM
(0 - 64K x 8)
Memory Configuration A
32 Registers
64 I/O Registers
Internal SRAM
(4096 x 8)
$0000 - $001F
$0020 - $005F
$1100
$10FF
$FFFF
$0060 - $00FF
Data Memory
External SRAM
(0 - 64K x 8)
160 Ext I/O Reg.
$0100
ATmega64A
7.2.1 Data Memory Access Times
This section describes the general access timing concepts for internal memory access. The
internal data SRAM access is performed in two clk
cycles as described in Figure 7-3.
CPU
8160C–AVR–07/09
20
Page 21

Figure 7-3. On-chip Data SRAM Access Cycles
clk
WR
RD
Data
Data
Address
Address Valid
T1 T2 T3
Compute Address
Read
Write
CPU
Memory Access Instruction
Next Instruction
ATmega64A
7.3 EEPROM Data Memory
The ATmega64A contains 2K bytes of data EEPROM memory. It is organized as a separate
data space, in which single bytes can be read and written. The EEPROM has an endurance of at
least 100,000 write/erase cycles. The access between the EEPROM and the CPU is described
in the following, specifying the EEPROM Address Registers, the EEPROM Data Register, and
the EEPROM Control Register.
“Memory Programming” on page 295 contains a detailed description on EEPROM programming
in SPI, JTAG, or Parallel Programming mode.
7.3.1 EEPROM Read/Write Access
The EEPROM Access Registers are accessible in the I/O space.
The write access time for the EEPROM is given in Table 7-5 on page 34. A self-timing function,
however, lets the user software detect when the next byte can be written. If the user code contains instructions that write the EEPROM, some precautions must be taken. In heavily filtered
power supplies, V
some period of time to run at a voltage lower than specified as minimum for the clock frequency
used. See “Preventing EEPROM Corruption” on page 22. for details on how to avoid problems in
these situations.
In order to prevent unintentional EEPROM writes, a specific write procedure must be followed.
Refer to the description of the EEPROM Control Register for details on this.
When the EEPROM is read, the CPU is halted for four clock cycles before the next instruction is
executed. When the EEPROM is written, the CPU is halted for two clock cycles before the next
instruction is executed.
is likely to rise or fall slowly on Power-up/down. This causes the device for
CC
7.3.2 EEPROM Write During Power-down Sleep Mode
When entering Power-down Sleep mode while an EEPROM write operation is active, the
EEPROM write operation will continue, and will complete before the Write Access time has
passed. However, when the write operation is completed, the oscillator continues running, and
8160C–AVR–07/09
21
Page 22

as a consequence, the device does not enter Power-down entirely. It is therefore recommended
to verify that the EEPROM write operation is completed before entering Power-down.
7.3.3 Preventing EEPROM Corruption
During periods of low V
too low for the CPU and the EEPROM to operate properly. These issues are the same as for
board level systems using EEPROM, and the same design solutions should be applied.
An EEPROM data corruption can be caused by two situations when the voltage is too low. First,
a regular write sequence to the EEPROM requires a minimum voltage to operate correctly. Secondly, the CPU itself can execute instructions incorrectly, if the supply voltage is too low.
EEPROM data corruption can easily be avoided by following this design recommendation:
Keep the AVR RESET active (low) during periods of insufficient power supply voltage. This can
be done by enabling the internal Brown-out Detector (BOD). If the detection level of the internal
BOD does not match the needed detection level, an external low V
can be used. If a reset occurs while a write operation is in progress, the write operation will be
completed provided that the power supply voltage is sufficient.
7.4 I/O Memory
The I/O space definition of the ATmega64A is shown in “Register Summary” on page 373.
ATmega64A
the EEPROM data can be corrupted because the supply voltage is
CC,
Reset Protection circuit
CC
All ATmega64A I/Os and peripherals are placed in the I/O space. All I/O locations may be
accessed by the LD/LDS/LDD and ST/STS/STD instructions, transferring data between the 32
general purpose working registers and the I/O space. I/O Registers within the address range
0x00 - 0x1F are directly bit-accessible using the SBI and CBI instructions. In these registers, the
value of single bits can be checked by using the SBIS and SBIC instructions. Refer to the
instruction set section for more details. When using the I/O specific commands IN and OUT, the
I/O addresses 0x00 - 0x3F must be used. When addressing I/O Registers as data space using
LD and ST instructions, 0x20 must be added to these addresses. The ATmega64A is a complex
microcontroller with more peripheral units than can be supported within the 64 location reserved
in Opcode for the IN and OUT instructions. For the Extended I/O space from 0x60 - 0xFF in
SRAM, only the ST/STS/STD and LD/LDS/LDD instructions can be used. The Extended I/O
space is replaced with SRAM locations when the ATmega64A is in the ATmega103 compatibility
mode.
For compatibility with future devices, reserved bits should be written to zero if accessed.
Reserved I/O memory addresses should never be written.
Some of the status flags are cleared by writing a logical one to them. Note that the CBI and SBI
instructions will operate on all bits in the I/O Register, writing a one back into any flag read as
set, thus clearing the flag. The CBI and SBI instructions work with registers 0x00 to 0x1F only.
The I/O and peripherals control registers are explained in later sections.
8160C–AVR–07/09
22
Page 23

7.5 External Memory Interface
Memory Configuration A
0x0000
0x10FF
External Memory
(0-60K x 8)
0xFFFF
Internal Memory
SRL[2..0]
SRW11
SRW10
SRW01
SRW00
Lower Sector
Upper Sector
0x1100
Memory Configuration B
0x0000
External Memory
(0-60K x 8)
0xFFFF
Internal Memory
SRW10
0x0FFF
0x1000
With all the features that the External Memory Interface provides, it is well suited to operate as
an interface to memory devices such as external SRAM and Flash, and peripherals such as
LCD-display, A/D, and D/A. The main features are:
• Four different wait-state settings (Including no wait-state).
• Independent wait-state setting for different external memory sectors (configurable sector
size).
• The number of bits dedicated to address high byte is selectable.
• Bus Keepers on data lines to minimize current consumption (optional).
7.5.1 Overview
When the eXternal MEMory (XMEM) is enabled, address space outside the internal SRAM
becomes available using the dedicated external memory pins (see Figure 1-1 on page 2, Table
13-3 on page 75, Table 13-9 on page 79, and Table 13-21 on page 87). The memory configura-
tion is shown in Figure 7-4.
ATmega64A
Figure 7-4. External Memory with Sector Select
(1)
Note: 1. ATmega64A in non ATmega103 compatibility mode: Memory Configuration A is available
(Memory Configuration B N/A).
ATmega64A in mega103 compatibility mode: Memory Configuration B is available (Memory
Configuration A N/A).
8160C–AVR–07/09
23
Page 24

7.5.2 ATmega103 Compatibility
Both External Memory Control Registers, XMCRA and XMCRB, are placed in Extended I/O
space. In ATmega103 compatibility mode, these registers are not available, and the features
selected by these registers are not available. The device is still ATmega103 compatible, as
these features did not exist in ATmega103. The limitations in ATmega103 compatibility mode
are:
• Only two wait-state settings are available (SRW1n = 0b00 and SRW1n = 0b01).
• The number of bits that are assigned to address high byte are fixed.
• The external memory section cannot be divided into sectors with different wait-state settings.
• Bus Keeper is not available.
•RD
, WR, and ALE pins are output only (Port G in ATmega64A).
7.5.3 Using the External Memory Interface
The interface consists of:
• AD7:0: Multiplexed low-order address bus and data bus.
• A15:8: High-order address bus (configurable number of bits).
• ALE: Address latch enable.
•RD
: Read strobe.
•WR
: Write strobe.
The control bits for the External Memory Interface are located in three registers, the MCU Control Register – MCUCR, the External Memory Control Register A – XMCRA, and the External
Memory Control Register B – XMCRB.
ATmega64A
When the XMEM interface is enabled, the XMEM interface will override the setting in the Data
Direction Registers that corresponds to the ports dedicated to the XMEM interface. For details
about the port override, see the alternate functions in section “I/O Ports” on page 68. The XMEM
interface will auto-detect whether an access is internal or external. If the access is external, the
XMEM interface will output address, data, and the control signals on the ports according to Fig-
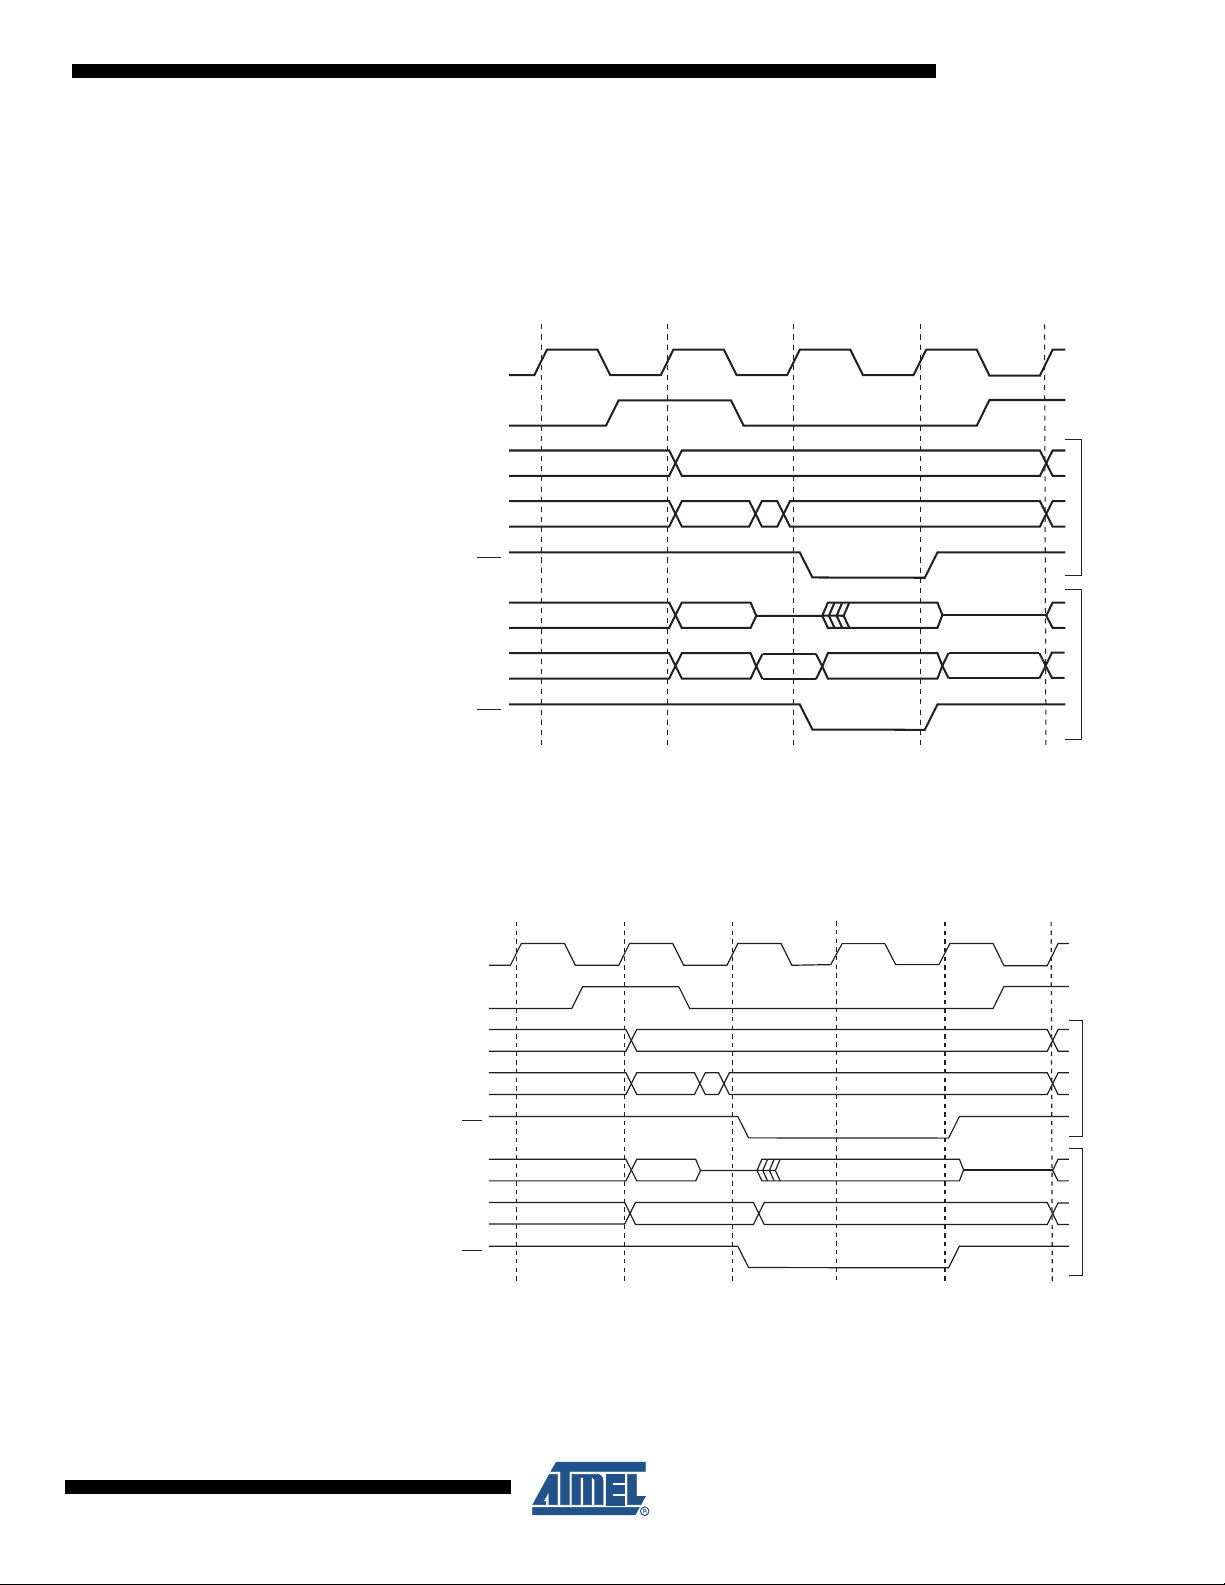
ure 7-6 (this figure shows the wave forms without wait states). When ALE goes from high-to-low,
there is a valid address on AD7:0. ALE is low during a data transfer. When the XMEM interface
is enabled, also an internal access will cause activity on address-, data- and ALE ports, but the
RD
and WR strobes will not toggle during internal access. When the external memory interface
is disabled, the normal pin and data direction settings are used. Note that when the XMEM interface is disabled, the address space above the internal SRAM boundary is not mapped into the
internal SRAM. Figure 7-5 illustrates how to connect an external SRAM to the AVR using an
octal latch (typically 74 x 573 or equivalent) which is transparent when G is high.
7.5.4 Address Latch Requirements
Due to the high-speed operation of the XRAM interface, the address latch must be selected with
care for system frequencies above 8 MHz @ 4V and 4 MHz @ 2.7V. When operating at conditions above these frequencies, the typical old style 74HC series latch becomes inadequate. The
external memory interface is designed in compliance to the 74AHC series latch. However, most
latches can be used as long they comply with the main timing parameters. The main parameters
for the address latch are:
8160C–AVR–07/09
24
Page 25

ATmega64A
D[7:0]
A[7:0]
A[15:8]
RD
WR
SRAM
DQ
G
AD7:0
ALE
A15:8
RD
WR
AVR
• D to Q propagation delay (tpd).
• Data setup time before G low (t
• Data (address) hold time after G low (
The external memory interface is designed to guaranty minimum address hold time after G is
asserted low of t
= 5 ns (refer to t
h
The D to Q propagation delay (t
time requirement of the external component. The data setup time before G low (t
exceed address valid to ALE low (t
load).
Figure 7-5. External SRAM Connected to the AVR
).
su
).
th
LAXX_LD/tLLAXX_ST
) must be taken into consideration when calculating the access
pd
) minus PCB wiring delay (dependent on the capacitive
AVLLC
in Table 28-8 to Table 28-15 on page 340).
) must not
su
7.5.5 Pull-up and Bus Keeper
The pull-ups on the AD7:0 ports may be activated if the corresponding Port Register is written to
one. To reduce power consumption in sleep mode, it is recommended to disable the pull-ups by
writing the Port Register to zero before entering sleep.
The XMEM interface also provides a Bus Keeper on the AD7:0 lines. The Bus Keeper can be
disabled and enabled in software as described in “XMCRB – External Memory Control Register
B” on page 32. When enabled, the Bus Keeper will ensure a defined logic level (zero or one) on
the AD7:0 bus when these lines would otherwise be tri-stated by the XMEM interface.
7.5.6 Timing
External memory devices have different timing requirements. To meet these requirements, the
ATmega64A XMEM interface provides four different wait states as shown in Table 7-3. It is
important to consider the timing specification of the external memory device before selecting the
wait-state. The most important parameters are the access time for the external memory compared to the set-up requirement of the ATmega64A. The access time for the external memory is
defined to be the time from receiving the chip select/address until the data of this address actually is driven on the bus. The access time cannot exceed the time from the ALE pulse is asserted
low until data must be stable during a read sequence (t
28-15 on page 340). The different wait states are set up in software. As an additional feature, it
is possible to divide the external memory space in two sectors with individual wait-state settings.
This makes it possible to connect two different memory devices with different timing requirements to the same XMEM interface. For XMEM interface timing details, please refer to Figure
28-6 to Figure 28-9, and Table 28-8 to Table 28-15.
LLRL
+ t
RLRH
- t
in Table 28-8 to Table
DVRH
8160C–AVR–07/09
25
Page 26
ATmega64A
ALE
T1 T2 T3
Write
Read
WR
T4
A15:8
AddressPrev. addr.
DA7:0
Address DataPrev. data XX
RD
DA7:0 (XMBK = 0)
DataPrev. data Address
DataPrev. data Address
DA7:0 (XMBK = 1)
System Clock (CLK
CPU
)
XXXXX
XXXXXXXX
ALE
T1 T2 T3
Write
Read
WR
T5
A15:8
AddressPrev. Addr.
DA7:0
Address DataPrev. Data XX
RD
DA7:0 (XMBK = 0)
DataPrev. Data Address
DataPrev. Data Address
DA7:0 (XMBK = 1)
System Clock (CLK
CPU
)
T4
Note that the XMEM interface is asynchronous and that the waveforms in the following figures
are related to the internal system clock. The skew between the internal and external clock
(XTAL1) is not guaranteed (varies between devices, temperature, and supply voltage). Consequently the XMEM interface is not suited for synchronous operation.
Figure 7-6. External Data Memory Cycles without Wait State
(1)
(SRWn1 = 0 and SRWn0 =0)
Note: 1. SRWn1 = SRW11 (upper sector) or SRW01 (lower sector), SRWn0 = SRW10 (upper sector) or
SRW00 (lower sector).
The ALE pulse in period T4 is only present if the next instruction accesses the RAM (internal
or external).
8160C–AVR–07/09
Figure 7-7. External Data Memory Cycles with SRWn1 = 0 and SRWn0 = 1
(1)
Note: 1. SRWn1 = SRW11 (upper sector) or SRW01 (lower sector), SRWn0 = SRW10 (upper sector) or
SRW00 (lower sector).
The ALE pulse in period T5 is only present if the next instruction accesses the RAM (internal
or external).
26
Page 27

ATmega64A
ALE
T1 T2 T3
Write
Read
WR
T6
A15:8
AddressPrev. Addr.
DA7:0
Address DataPrev. Data XX
RD
DA7:0 (XMBK = 0)
DataPrev. Data Address
DataPrev. Data Address
DA7:0 (XMBK = 1)
System Clock (CLK
CPU
)
T4 T5
ALE
T1 T2 T3
Write
Read
WR
T7
A15:8
AddressPrev. Addr.
DA7:0
Address DataPrev. Data
XX
RD
DA7:0 (XMBK = 0)
DataPrev. Data Address
DataPrev. Data Address
DA7:0 (XMBK = 1)
System Clock (CLK
CPU
)
T4 T5 T6
Figure 7-8. External Data Memory Cycles with SRWn1 = 1 and SRWn0 = 0
(1)
Note: 1. SRWn1 = SRW11 (upper sector) or SRW01 (lower sector), SRWn0 = SRW10 (upper sector) or
SRW00 (lower sector).
The ALE pulse in period T6 is only present if the next instruction accesses the RAM (internal
or external).
Figure 7-9. External Data Memory Cycles with SRWn1 = 1 and SRWn0 = 1
(1)
7.5.7 Using all Locations of External Memory Smaller than 64 KB
8160C–AVR–07/09
Note: 1. SRWn1 = SRW11 (upper sector) or SRW01 (lower sector), SRWn0 = SRW10 (upper sector) or
SRW00 (lower sector).
The ALE pulse in period T7 is only present if the next instruction accesses the RAM (internal
or external).
Since the external memory is mapped after the internal memory as shown in Figure 7-4 on page
23, the external memory is not addressed when addressing the first 4,352 bytes of data space. It
may appear that the first 4,352 bytes of the external memory are inaccessible (external memory
addresses 0x0000 to 0x10FF). However, when connecting an external memory smaller than 64
KB, for example 32 KB, these locations are easily accessed simply by addressing from address
0x8000 to 0x90FF. Since the External Memory Address bit A15 is not connected to the external
memory, addresses 0x8000 to 0x90FF will appear as addresses 0x0000 to 0x10FF for the external memory. Addressing above address 0x90FF is not recommended, since this will address an
external memory location that is already accessed by another (lower) address. To the Application software, the external 32 KB memory will appear as one linear 32 KB address space from
27
Page 28
ATmega64A
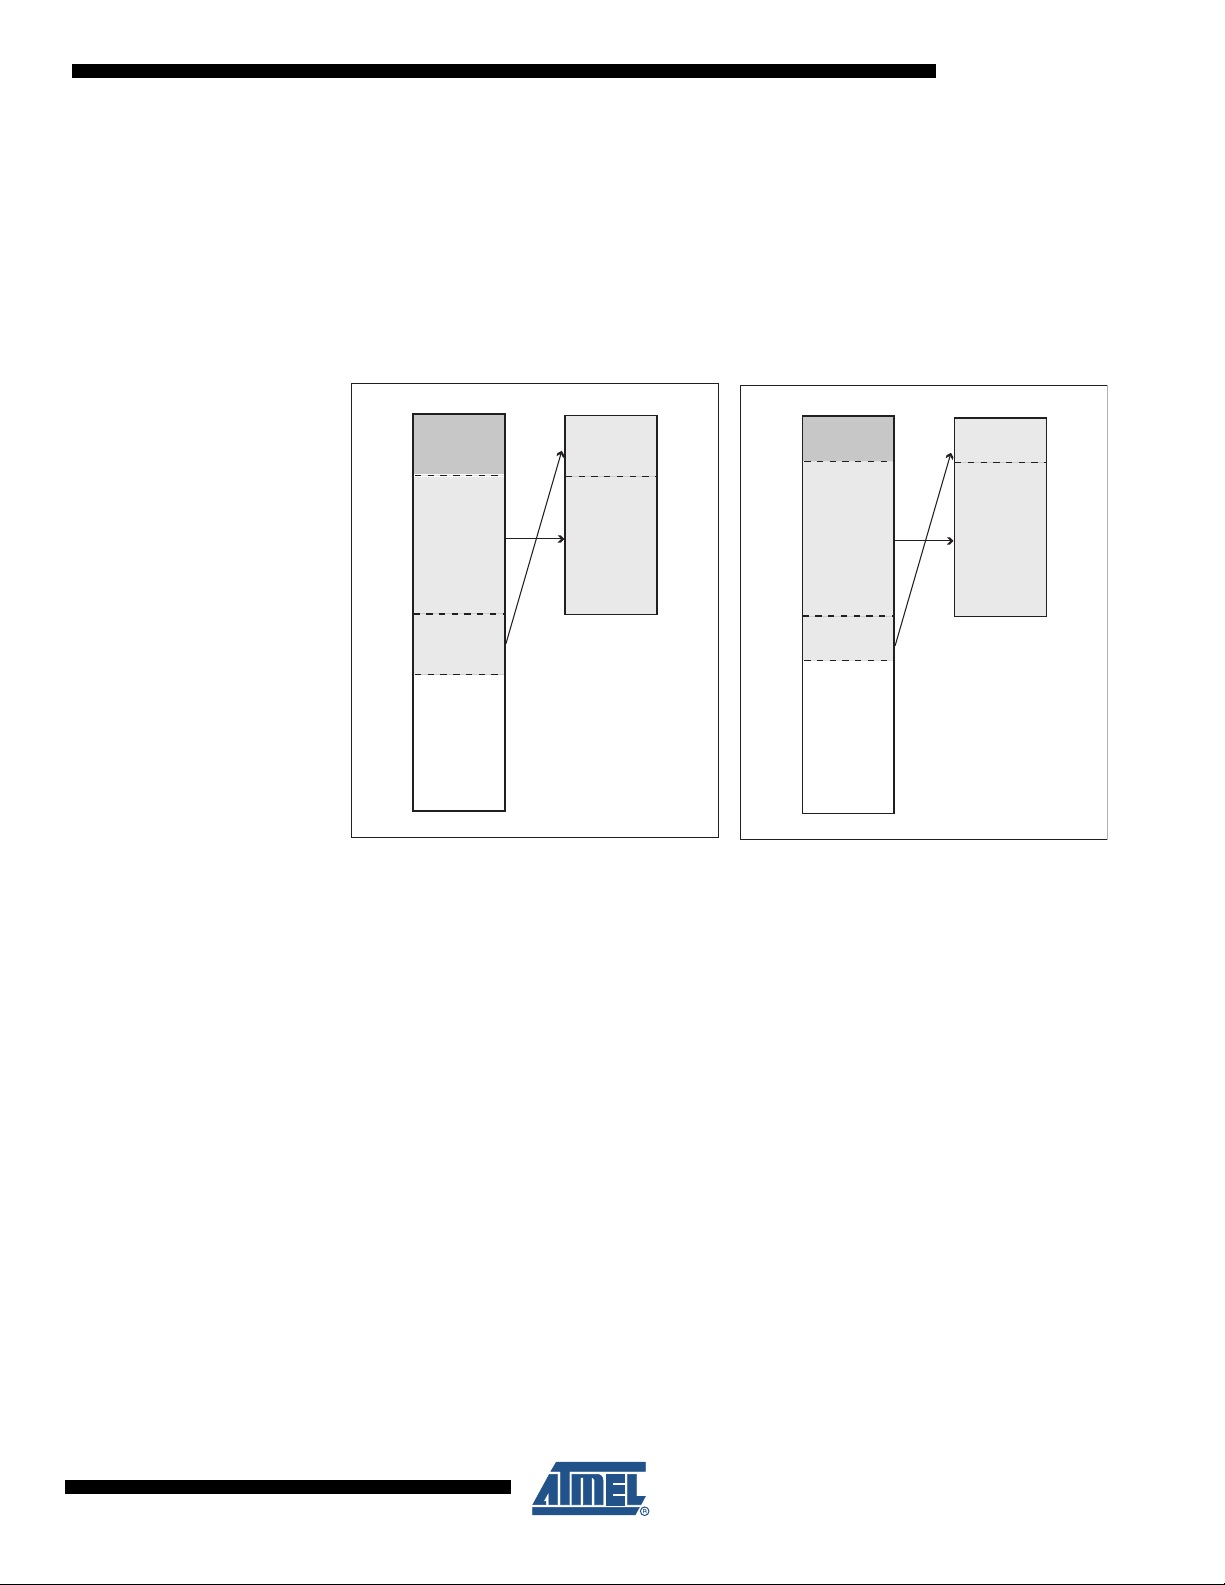
0x1100 to 0x90FF. This is illustrated in Figure 7-10. Memory configuration B refers to the
ATmega103 compatibility mode, configuration A to the non-compatible mode.
When the device is set in ATmega103 compatibility mode, the internal address space is 4,096
bytes. This implies that the first 4,096 bytes of the external memory can be accessed at
addresses 0x8000 to 0x8FFF. To the Application software, the external 32 KB memory will
appear as one linear 32 KB address space from 0x1000 to 0x8FFF.
Figure 7-10. Address Map with 32 KB External Memory
Memory Configuration B
AVR Memory Map
Internal Memory
External 32K SRAM
0x0000
0x0FFF
0x1000
0x0000
0x10FF
0x1100
Memory Configuration A
AVR Memory Map
Internal Memory
External 32K SRAM
0x0000
0x10FF
0x1100
0x0000
0x0FFF
0x1000
0x7FFF
0x8000
0x90FF
0x9100
0xFFFF
External
Memory
(Unused)
7.5.8 Using all 64KB Locations of External Memory
Since the external memory is mapped after the internal memory as shown in Figure 7-4, only
60KB of external memory is available by default (address space 0x0000 to 0x10FF is reserved
for internal memory). However, it is possible to take advantage of the entire external memory by
masking the higher address bits to zero. This can be done by using the XMMn bits and controlled by software the most significant bits of the address. By setting Port C to output 0x00, and
releasing the most significant bits for normal Port Pin operation, the Memory Interface will
address 0x0000 - 0x1FFF. See code examples below.
0x7FFF
0x7FFF
0x8000
0x8FFF
0x9000
0xFFFF
External
Memory
(Unused)
0x7FFF
8160C–AVR–07/09
28
Page 29

ATmega64A
Assembly Code Example
; OFFSET is defined to 0x2000 to ensure
; external memory access
; Configure Port C (address high byte) to
; output 0x00 when the pins are released
; for normal Port Pin operation
ldi r16, 0xFF
out DDRC, r16
ldi r16, 0x00
out PORTC, r16
; release PC7:5
ldi r16, (1<<XMM1)|(1<<XMM0)
sts XMCRB, r16
; write 0xAA to address 0x0001 of external
; memory
ldi r16, 0xaa
sts 0x0001+OFFSET, r16
; re-enable PC7:5 for external memory
ldi r16, (0<<XMM1)|(0<<XMM0)
sts XMCRB, r16
; store 0x55 to address (OFFSET + 1) of
; external memory
ldi r16, 0x55
sts 0x0001+OFFSET, r16
C Code Example
#define OFFSET 0x2000
(1)
(1)
void XRAM_example(void)
{
unsigned char *p = (unsigned char *) (OFFSET + 1);
DDRC = 0xFF;
PORTC = 0x00;
XMCRB = (1<<XMM1) | (1<<XMM0);
*p = 0xaa;
XMCRB = 0x00;
*p = 0x55;
}
Note: 1. See “About Code Examples” on page 8.
Care must be exercised using this option as most of the memory is masked away.
8160C–AVR–07/09
29
Page 30

7.6 Register Description
7.6.1 MCUCR – MCU Control Register
Bit 76543210
0x35 (0x55) SRE SRW10
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value00000000
• Bit 7 – SRE: External SRAM/XMEM Enable
Writing SRE to one enables the External Memory Interface.The pin functions AD7:0, A15:8,
ALE, WR
direction settings in the respective data direction registers. Writing SRE to zero, disables the
External Memory Interface and the normal pin and data direction settings are used.
• Bit 6 – SRW10: Wait State Select Bit
For a detailed description in non ATmega103 compatibility mode, see common description for
the SRWn bits below (XMRA description). In ATmega103 compatibility mode, writing SRW10 to
one enables the wait state and one extra cycle is added during read/write strobe as shown in
Figure 7-7.
, and RD are activated as the alternate pin functions. The SRE bit overrides any pin
ATmega64A
SE SM1 SM0 SM2 IVSEL IVCE MCUCR
7.6.2 XMCRA – External Memory Control Register A
Bit 76543210
(0x6D) – SRL2 SRL1 SRL0 SRW01 SRW00 SRW11 – XMCRA
Read/Write R R/W R/W R/W R/W R/W R/W R
Initial Value00000000
• Bit 7 – Res: Reserved Bit
This is a reserved bit and will always read as zero. When writing to this address location, write
this bit to zero for compatibility with future devices.
• Bit 6:4 – SRL2, SRL1, SRL0: Wait State Sector Limit
It is possible to configure different wait states for different external memory addresses. The
external memory address space can be divided in two sectors that have separate wait-state bits.
The SRL2, SRL1, and SRL0 bits select the split of the sectors, see Table 7-2 and Figure 7-4. By
default, the SRL2, SRL1, and SRL0 bits are set to zero and the entire external memory address
space is treated as one sector. When the entire SRAM address space is configured as one sector, the wait states are configured by the SRW11 and SRW10 bits.
8160C–AVR–07/09
30
Page 31
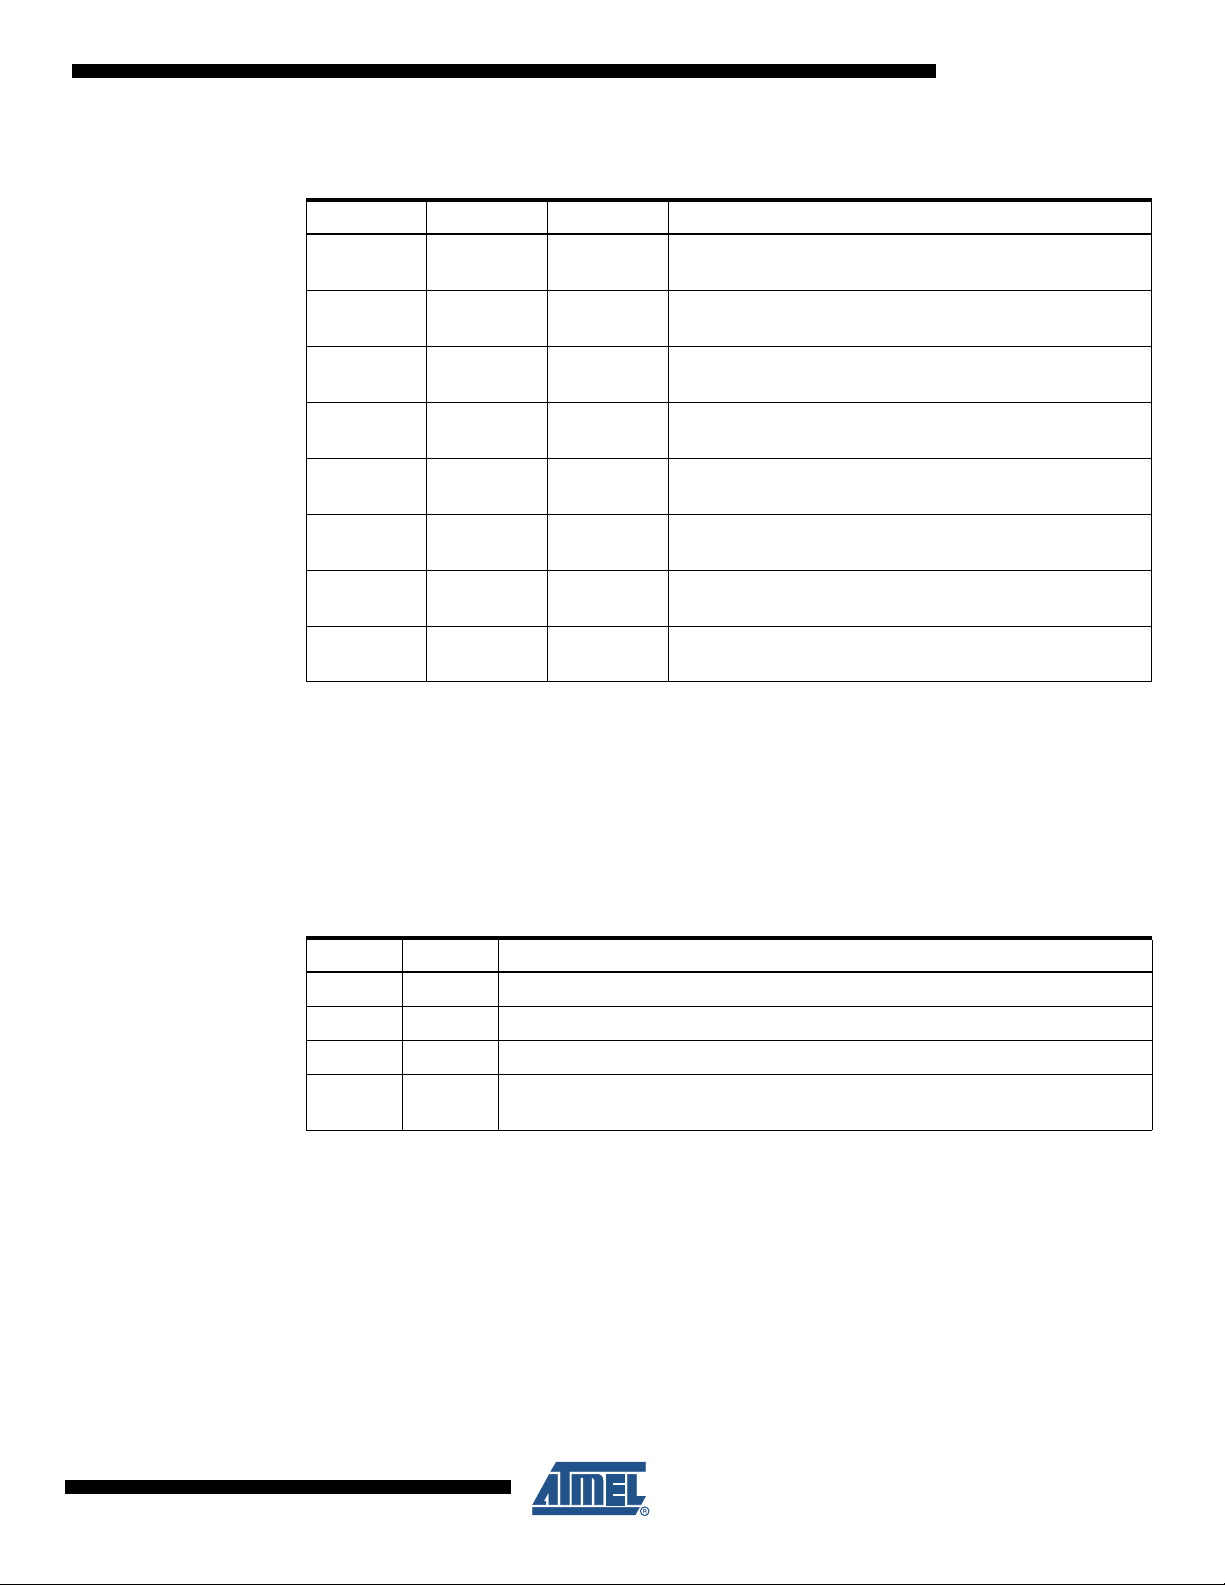
Table 7-2. Sector Limits with Different Settings of SRL2:0
SRL2 SRL1 SRL0 Sector Limits
0 0 0 Lower sector = N/A
Upper sector = 0x1100 - 0xFFFF
0 0 1 Lower sector = 0x1100 - 0x1FFF
Upper sector = 0x2000 - 0xFFFF
0 1 0 Lower sector = 0x1100 - 0x3FFF
Upper sector = 0x4000 - 0xFFFF
0 1 1 Lower sector = 0x1100 - 0x5FFF
Upper sector = 0x6000 - 0xFFFF
1 0 0 Lower sector = 0x1100 - 0x7FFF
Upper sector = 0x8000 - 0xFFFF
1 0 1 Lower sector = 0x1100 - 0x9FFF
Upper sector = 0xA000 - 0xFFFF
1 1 0 Lower sector = 0x1100 - 0xBFFF
Upper sector = 0xC000 - 0xFFFF
1 1 1 Lower sector = 0x1100 - 0xDFFF
Upper sector = 0xE000 - 0xFFFF
ATmega64A
• Bit 1 and Bit 6 MCUCR – SRW11, SRW10: Wait State Select Bits for Upper Sector
The SRW11 and SRW10 bits control the number of wait states for the upper sector of the external memory address space, see Table 7-3.
• Bit 3:2 – SRW01, SRW00: Wait State Select Bits for Lower Sector
The SRW01 and SRW00 bits control the number of wait states for the lower sector of the external memory address space, see Table 7-3.
Table 7-3. Wait States
SRWn1 SRWn0 Wait States
00No wait states
0 1 Wait one cycle during read/write strobe
1 0 Wait two cycles during read/write strobe
11
Note: 1. n = 0 or 1 (lower/upper sector).
For further details of the timing and wait states of the External Memory Interface, see Figure 7-
6 to Figure 7-9 how the setting of the SRW bits affects the timing.
(1)
Wait two cycles during read/write and wait one cycle before driving out new
address
• Bit 0 – Res: Reserved Bit
This is a reserved bit and will always read as zero. When writing to this address location, write
this bit to zero for compatibility with future devices.
8160C–AVR–07/09
31
Page 32
7.6.3 XMCRB – External Memory Control Register B
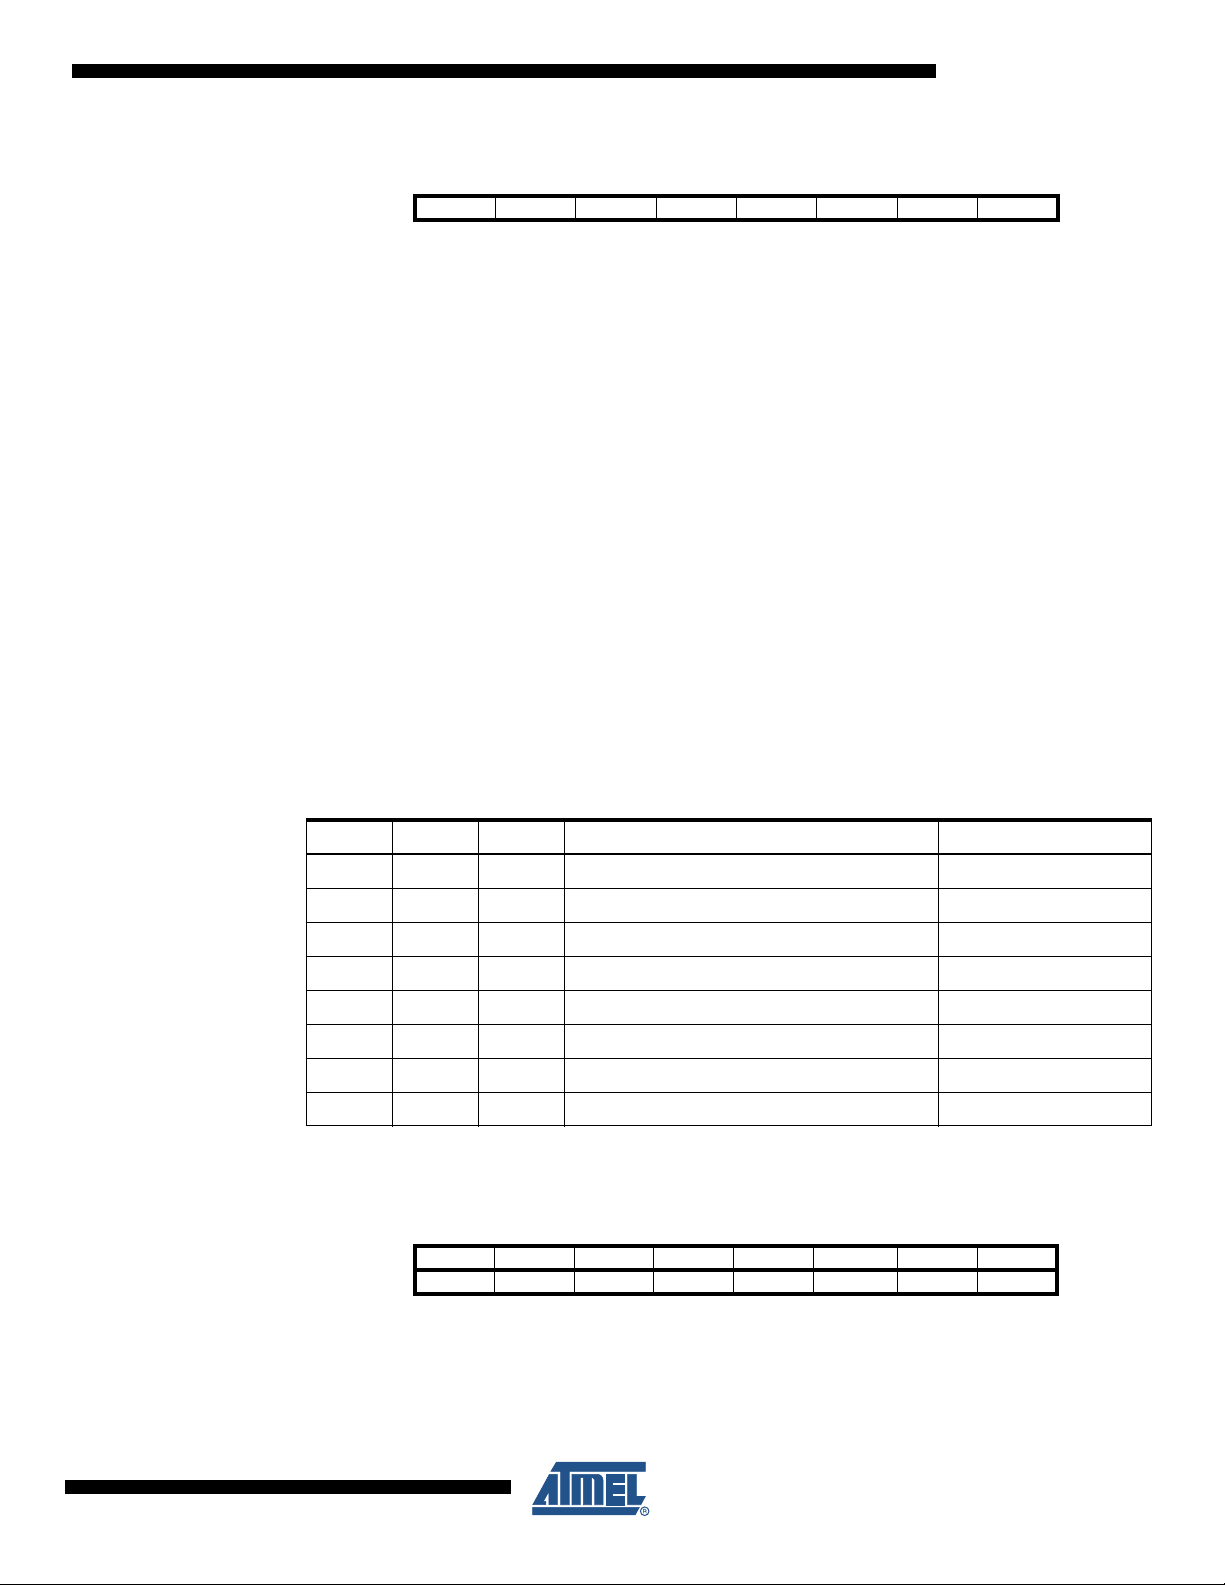
Bit 76543210
(0x6C) XMBK – – – – XMM2 XMM1 XMM0 XMCRB
Read/Write R/W R R R R R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
• Bit 7 – XMBK: External Memory Bus Keeper Enable
Writing XMBK to one enables the Bus Keeper on the AD7:0 lines. When the Bus Keeper is
enabled, it will ensure a defined logic level (zero or one) on AD7:0 when they would otherwise
be tri-stated. Writing XMBK to zero disables the Bus Keeper. XMBK is not qualified with SRE, so
even if the XMEM interface is disabled, the Bus Keepers are still activated as long as XMBK is
one.
• Bit 6:3 – Res: Reserved Bits
These are reserved bits and will always read as zero. When writing to this address location,
write these bits to zero for compatibility with future devices.
• Bit 2:0 – XMM2, XMM1, XMM0: External Memory High Mask
When the External Memory is enabled, all Port C pins are default used for the high address byte.
If the full 60KB address space is not required to access the external memory, some, or all, Port
C pins can be released for normal port pin function as described in Table 7-4. As described in
“Using all Locations of External Memory Smaller than 64 KB” on page 27, it is possible to use
the XMMn bits to access all 64KB locations of the external memory.
ATmega64A
Table 7-4. Port C Pins Released as Normal Port Pins when the External Memory is Enabled
XMM2 XMM1 XMM0 # Bits for External Memory Address Released Port Pins
0 0 0 8 (Full 60 KB space) None
0017 PC7
0 1 0 6 PC7 - PC6
0 1 1 5 PC7 - PC5
1 0 0 4 PC7 - PC4
1 0 1 3 PC7 - PC3
1 1 0 2 PC7 - PC2
1 1 1 No Address high bits Full Port C
7.6.4 EEARH and EEARL – EEPROM Address Register
Bit 1514131211 10 9 8
0x1F (0x3F) – – – – – EEAR10 EEAR9 EEAR8 EEARH
0x1E (0x3E) EEAR7 EEAR6 EEAR5 EEAR4 EEAR3 EEAR2 EEAR1 EEAR0 EEARL
76543 2 10
Read/Write R R R R R R/W R/W R/W
R/WR/WR/WR/WR/W R/W R/WR/W
Initial Value 0 0 0 0 0 X X X
XXXXX XXX
8160C–AVR–07/09
32
Page 33
• Bits 15:11 – Res: Reserved Bits
These are reserved bits and will always read as zero. When writing to this address location,
write these bits to zero for compatibility with future devices.
• Bits 10:0 – EEAR10:0: EEPROM Address
The EEPROM Address Registers – EEARH and EEARL specify the EEPROM address in the 2K
bytes EEPROM space. The EEPROM data bytes are addressed linearly between 0 and 2,048.
The Initial Value of EEAR is undefined. A proper value must be written before the EEPROM may
be accessed.
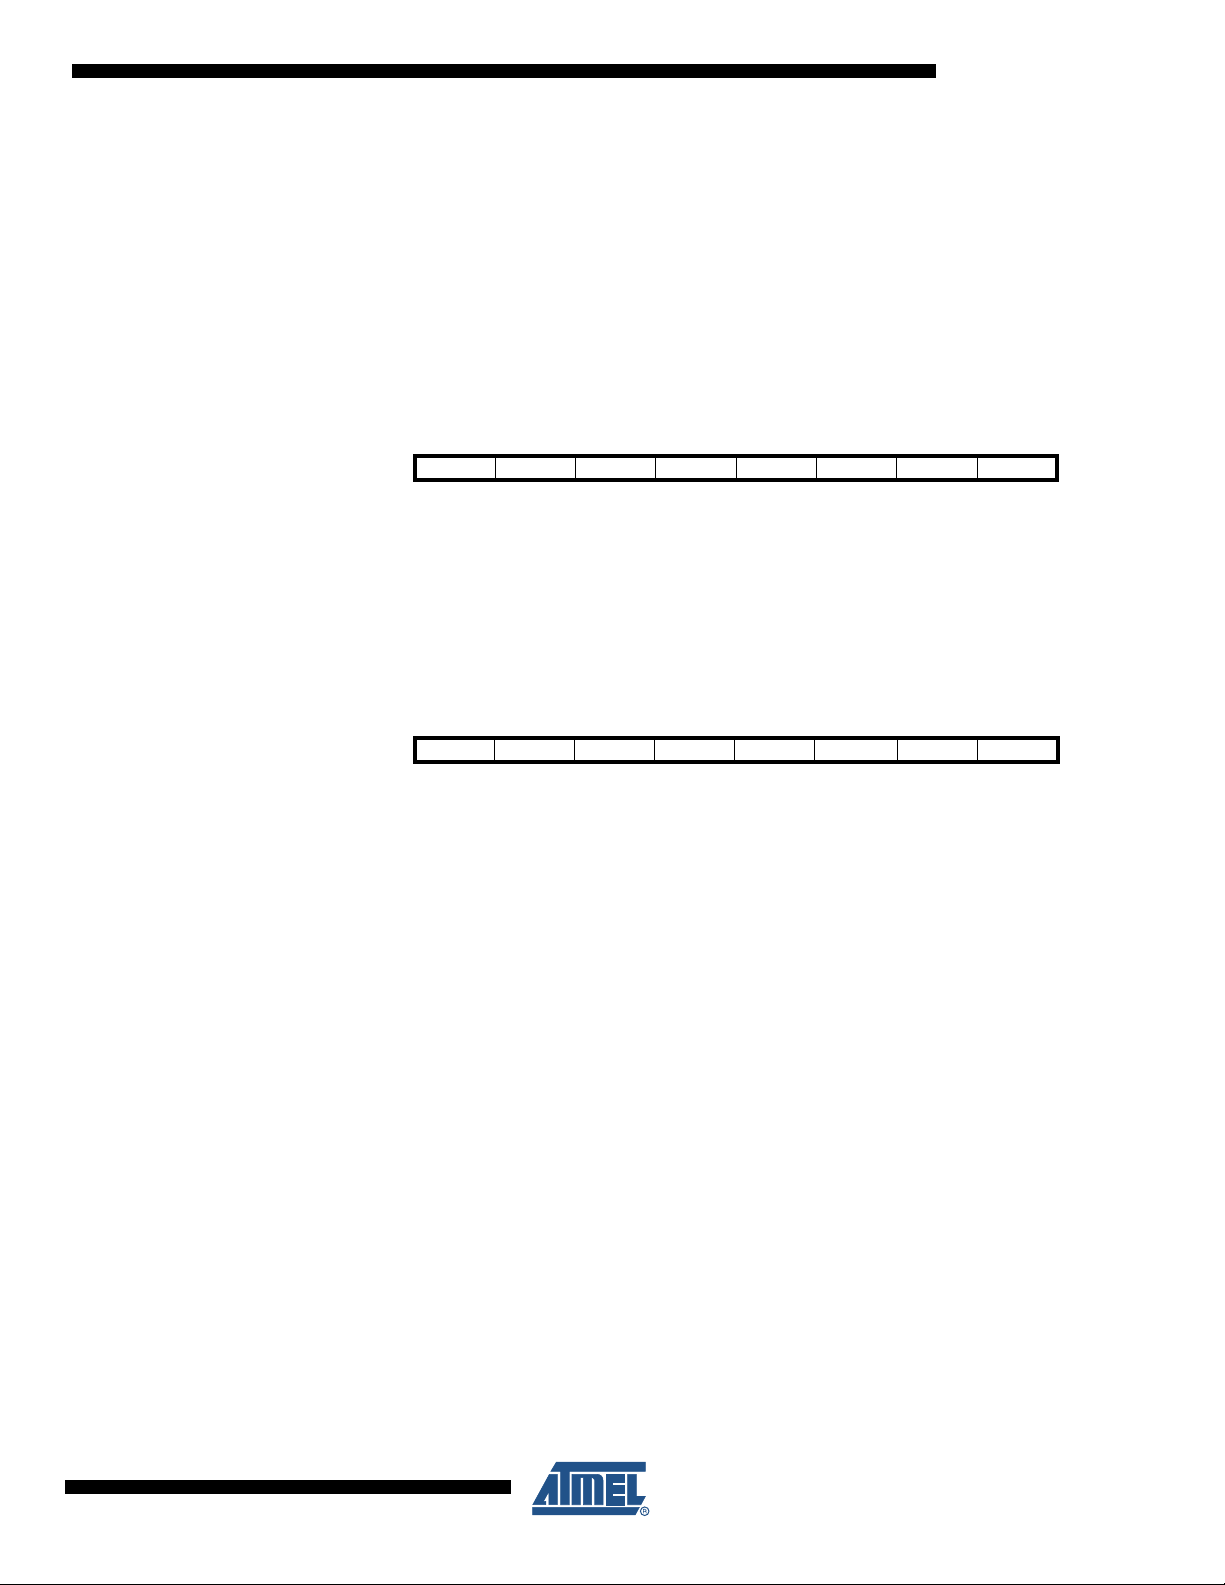
7.6.5 EEDR – EEPROM Data Register
Bit 76543210
0x1D (0x3D) MSB LSB EEDR
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value00000000
• Bits 7:0 – EEDR7.0: EEPROM Data
For the EEPROM write operation, the EEDR Register contains the data to be written to the
EEPROM in the address given by the EEAR Register. For the EEPROM read operation, the
EEDR contains the data read out from the EEPROM at the address given by EEAR.
ATmega64A
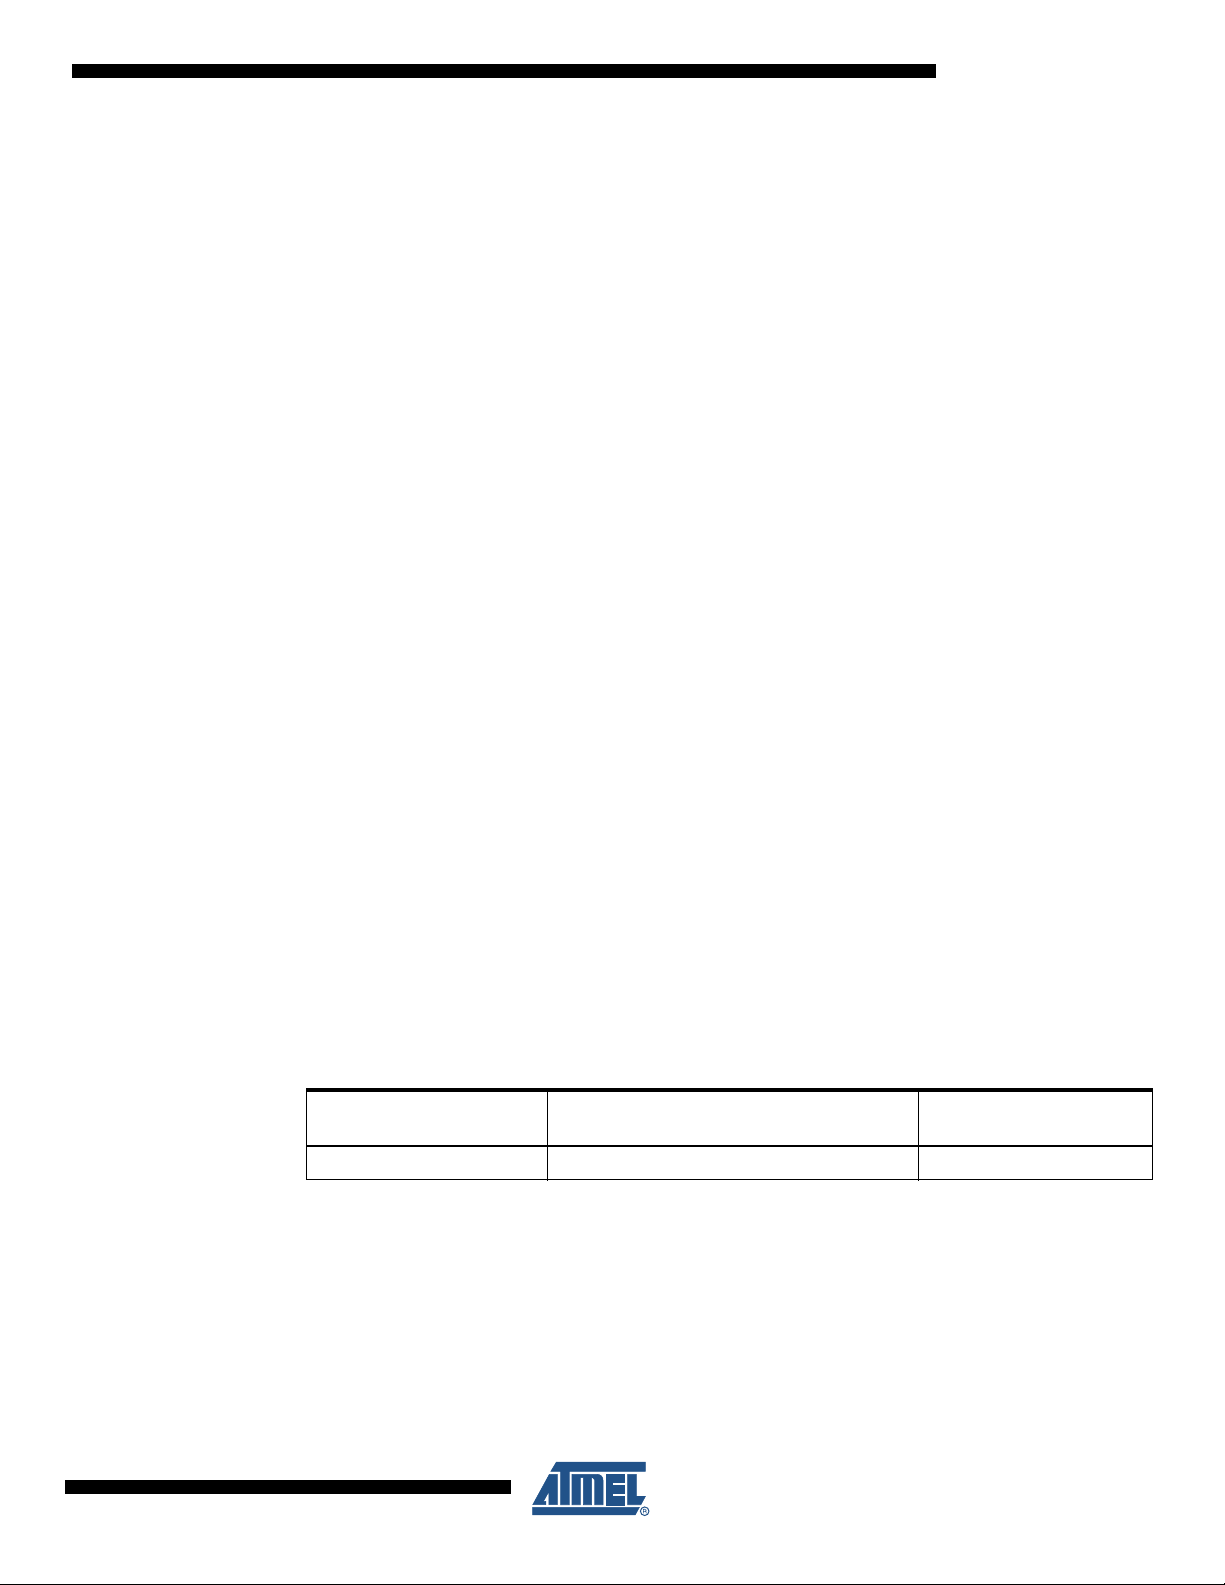
7.6.6 EECR – EEPROM Control Register
Bit 76543210
0x1C (0x3C) – – – – EERIE EEMWE EEWE EERE EECR
Read/WriteRRRRR/WR/WR/WR/W
Initial Value 0 0 0 0 0 0 X 0
• Bits 7:4 – Res: Reserved Bits
These bits are reserved bits in the ATmega64A and will always read as zero.
• Bit 3 – EERIE: EEPROM Ready Interrupt Enable
Writing EERIE to one enables the EEPROM Ready Interrupt if the I-bit in SREG is set. Writing
EERIE to zero disables the interrupt. The EEPROM Ready Interrupt generates a constant interrupt when EEWE is cleared.
• Bit 2 – EEMWE: EEPROM Master Write Enable
The EEMWE bit determines whether setting EEWE to one causes the EEPROM to be written.
When EEMWE is written to one, writing EEWE to one within four clock cycles will write data to
the EEPROM at the selected address. If EEMWE is zero, writing EEWE to one will have no
effect. When EEMWE has been written to one by software, hardware clears the bit to zero after
four clock cycles. See the description of the EEWE bit for an EEPROM write procedure.
• Bit 1 – EEWE: EEPROM Write Enable
The EEPROM Write Enable Signal EEWE is the write strobe to the EEPROM. When address
and data are correctly set up, the EEWE bit must be set to write the value into the EEPROM.
The EEMWE bit must be set when the logical one is written to EEWE, otherwise no EEPROM
write takes place. The following procedure should be followed when writing the EEPROM (the
order of steps 3 and 4 is not essential):
8160C–AVR–07/09
33
Page 34
ATmega64A
1. Wait until EEWE becomes zero.
2. Wait until SPMEN in SPMCSR becomes zero.
3. Write new EEPROM address to EEAR (optional).
4. Write new EEPROM data to EEDR (optional).
5. Write a logical one to the EEMWE bit while writing a zero to EEWE in EECR.
6. Within four clock cycles after setting EEMWE, write a logical one to EEWE.
The EEPROM can not be programmed during a CPU write to the Flash memory. The software
must check that the Flash programming is completed before initiating a new EEPROM write.
Step 2 is only relevant if the software contains a Boot Loader allowing the CPU to program the
Flash. If the Flash is never being updated by the CPU, step 2 can be omitted. See “Boot Loader
Support – Read-While-Write Self-programming” on page 281 for details about Boot
programming.
Caution: An interrupt between step 5 and step 6 will make the write cycle fail, since the
EEPROM Master Write Enable will time-out. If an interrupt routine accessing the EEPROM is
interrupting another EEPROM access, the EEAR or EEDR Register will be modified, causing the
interrupted EEPROM access to fail. It is recommended to have the Global Interrupt Flag cleared
during the four last steps to avoid these problems.
When the write access time has elapsed, the EEWE bit is cleared by hardware. The user software can poll this bit and wait for a zero before writing the next byte. When EEWE has been set,
the CPU is halted for two cycles before the next instruction is executed.
• Bit 0 – EERE: EEPROM Read Enable
The EEPROM Read Enable Signal EERE is the read strobe to the EEPROM. When the correct
address is set up in the EEAR Register, the EERE bit must be written to a logic one to trigger the
EEPROM read. The EEPROM read access takes one instruction, and the requested data is
available immediately. When the EEPROM is read, the CPU is halted for four cycles before the
next instruction is executed.
The user should poll the EEWE bit before starting the read operation. If a write operation is in
progress, it is neither possible to read the EEPROM, nor to change the EEAR Register.
The calibrated Oscillator is used to time the EEPROM accesses. Table 7-5 lists the typical programming time for EEPROM access from the CPU.
Table 7-5. EEPROM Programming Time
Number of Calibrated RC Oscillator
Symbol
EEPROM write (from CPU) 8448 8.4 ms
Note: 1. Uses 1 MHz clock, independent of CKSEL Fuse settings.
(1)
Cycles Typ Programming Time
The following code examples show one assembly and one C function for writing to the
EEPROM. The examples assume that interrupts are controlled (e.g., by disabling interrupts
globally) so that no interrupts will occur during execution of these functions. The examples also
assume that no Flash boot loader is present in the software. If such code is present, the
EEPROM write function must also wait for any ongoing SPM command to finish.
8160C–AVR–07/09
34
Page 35
Assembly Code Example
EEPROM_write:
; Wait for completion of previous write
sbic EECR,EEWE
rjmp EEPROM_write
; Set up address (r18:r17) in address register
out EEARH, r18
out EEARL, r17
; Write data (r16) to data register
out EEDR,r16
; Write logical one to EEMWE
sbi EECR,EEMWE
; Start eeprom write by setting EEWE
sbi EECR,EEWE
ret
C Code Example
void EEPROM_write(unsigned int uiAddress, unsigned char ucData)
{
/* Wait for completion of previous write */
while(EECR & (1<<EEWE))
;
/* Set up address and data registers */
EEAR = uiAddress;
EEDR = ucData;
/* Write logical one to EEMWE */
EECR |= (1<<EEMWE);
/* Start eeprom write by setting EEWE */
EECR |= (1<<EEWE);
}
ATmega64A
8160C–AVR–07/09
35
Page 36
ATmega64A
The next code examples show assembly and C functions for reading the EEPROM. The examples assume that interrupts are controlled so that no interrupts will occur during execution of
these functions.
Assembly Code Example
EEPROM_read:
; Wait for completion of previous write
sbic EECR,EEWE
rjmp EEPROM_read
; Set up address (r18:r17) in address register
out EEARH, r18
out EEARL, r17
; Start eeprom read by writing EERE
sbi EECR,EERE
; Read data from data register
in r16,EEDR
ret
C Code Example
unsigned char EEPROM_read(unsigned int uiAddress)
{
/* Wait for completion of previous write */
while(EECR & (1<<EEWE))
;
/* Set up address register */
EEAR = uiAddress;
/* Start eeprom read by writing EERE */
EECR |= (1<<EERE);
/* Return data from data register */
return EEDR;
}
8160C–AVR–07/09
36
Page 37
8. System Clock and Clock Options
General I/O
Modules
Asynchronous
Timer/Counter
ADC CPU Core RAM
clk
I/O
clk
ASY
AVR Clock
Control Unit
clk
CPU
Flash and
EEPROM
clk
FLASH
clk
ADC
Source Clock
Watchdog Timer
Watchdog
Oscillator
Reset Logic
Clock
Multiplexer
Watchdog Clock
Calibrated RC
Oscillator
Timer/Counter
Oscillator
Crystal
Oscillator
Low-frequency
Crystal Oscillator
External RC
Oscillator
External Clock
8.1 Clock Systems and their Distribution
Figure 8-1 presents the principal clock systems in the AVR and their distribution. All of the clocks
need not be active at a given time. In order to reduce power consumption, the clocks to modules
not being used can be halted by using different sleep modes, as described in “Power Manage-
ment and Sleep Modes” on page 46. The clock systems are detailed below.
Figure 8-1. Clock Distribution
ATmega64A
8.1.1 CPU Clock – clk
8.1.2 I/O Clock – clk
8160C–AVR–07/09
CPU
The CPU clock is routed to parts of the system concerned with operation of the AVR core.
Examples of such modules are the General Purpose Register File, the Status Register and the
data memory holding the Stack Pointer. Halting the CPU clock inhibits the core from performing
general operations and calculations.
I/O
The I/O clock is used by the majority of the I/O modules, like Timer/Counters, SPI, and USART.
The I/O clock is also used by the External Interrupt module, but note that some external interrupts are detected by asynchronous logic, allowing such interrupts to be detected even if the I/O
clock is halted. Also note that address recognition in the TWI module is carried out asynchronously when clk
is halted, enabling TWI address reception in all sleep modes.
I/O
37
Page 38
ATmega64A
8.1.3 Flash Clock – clk
FLASH
The Flash clock controls operation of the Flash interface. The Flash clock is usually active simultaneously with the CPU clock.
8.1.4 Asynchronous Timer Clock – clk
The Asynchronous Timer clock allows the Asynchronous Timer/Counter to be clocked directly
from an external 32 kHz clock crystal. The dedicated clock domain allows using this
Timer/Counter as a real-time counter even when the device is in sleep mode.
8.1.5 ADC Clock – clk
ADC
The ADC is provided with a dedicated clock domain. This allows halting the CPU and I/O clocks
in order to reduce noise generated by digital circuitry. This gives more accurate ADC conversion
results.
8.2 Clock Sources
The device has the following clock source options, selectable by Flash Fuse bits as shown
below. The clock from the selected source is input to the AVR clock generator, and routed to the
appropriate modules.
Table 8-1. Device Clocking Options Select
Device Clocking Option CKSEL3:0
External Crystal/Ceramic Resonator 1111 - 1010
External Low-frequency Crystal 1001
External RC Oscillator 1000 - 0101
ASY
(1)
Calibrated Internal RC Oscillator 0100 - 0001
External Clock 0000
Note: 1. For all fuses “1” means unprogrammed while “0” means programmed.
The various choices for each clocking option is given in the following sections. When the CPU
wakes up from Power-down or Power-save, the selected clock source is used to time the startup, ensuring stable Oscillator operation before instruction execution starts. When the CPU starts
from reset, there is as an additional delay allowing the power to reach a stable level before commencing normal operation. The Watchdog Oscillator is used for timing this real-time part of the
start-up time. The number of WDT Oscillator cycles used for each time-out is shown in Table 8-
2. The frequency of the Watchdog Oscillator is voltage dependent as shown in the “Typical
Characteristics” on page 343.
Table 8-2. Number of Watchdog Oscillator Cycles
Typ Time-out (VCC = 5.0V) Typ Time-out (VCC = 3.0V) Number of Cycles
8.3 Default Clock Source
The device is shipped with CKSEL = “0001” and SUT = “10”. The default clock source setting is
therefore the Internal RC Oscillator with longest startup time. This default setting ensures that all
users can make their desired clock source setting using an In-System or Parallel Programmer.
4.1 ms 4.3 ms 4K (4,096)
65 ms 69 ms 64K (65,536)
8160C–AVR–07/09
38
Page 39
8.4 Crystal Oscillator
XTAL2
XTAL1
GND
C2
C1
XTAL1 and XTAL2 are input and output, respectively, of an inverting amplifier which can be configured for use as an On-chip Oscillator, as shown in Figure 8-2. Either a quartz crystal or a
ceramic resonator may be used. The CKOPT Fuse selects between two different Oscillator
amplifier modes. When CKOPT is programmed, the Oscillator output will oscillate a full rail-torail swing on the output. This mode is suitable when operating in a very noisy environment or
when the output from XTAL2 drives a second clock buffer. This mode has a wide frequency
range. When CKOPT is unprogrammed, the Oscillator has a smaller output swing. This reduces
power consumption considerably. This mode has a limited frequency range and it cannot be
used to drive other clock buffers.
For resonators, the maximum frequency is 8 MHz with CKOPT unprogrammed and 16 MHz with
CKOPT programmed. C1 and C2 should always be equal for both crystals and resonators. The
optimal value of the capacitors depends on the crystal or resonator in use, the amount of stray
capacitance, and the electromagnetic noise of the environment. Some initial guidelines for
choosing capacitors for use with crystals are given in Table 8-3. For ceramic resonators, the
capacitor values given by the manufacturer should be used.
Figure 8-2. Crystal Oscillator Connections
ATmega64A
8160C–AVR–07/09
The Oscillator can operate in three different modes, each optimized for a specific frequency
range. The operating mode is selected by the fuses CKSEL3:1 as shown in Table 8-3.
Figure 8-3. Crystal Oscillator Operating Modes
Frequency Range
CKOPT CKSEL3:1
1 101
1 110 0.9 - 3.0 12 - 22
1 111 3.0 - 8.0 12 - 22
0 101, 110, 111 1.0 - 12 - 22
Note: 1. This option should not be used with crystals, only with ceramic resonators.
(1)
(MHz)
0.4 - 0.9 –
Recommended Range for Capacitors
C1 and C2 for Use with Crystals (pF)
The CKSEL0 Fuse together with the SUT1:0 Fuses select the start-up times as shown in Table
8-3.
39
Page 40
Table 8-3. Start-up Times for the Crystal Oscillator Clock Selection
ATmega64A
Start-up Time from
Power-down and
CKSEL0 SUT1:0
0 00 258 CK
0 01 258 CK
010 1K CK
011 1K CK
100 1K CK
1 01 16K CK –
1 10 16K CK 4.1 ms
1 11 16K CK 65 ms
Notes: 1. These options should only be used when not operating close to the maximum frequency of the
device, and only if frequency stability at start-up is not important for the application. These
options are not suitable for crystals.
2. These options are intended for use with ceramic resonators and will ensure frequency stability
at start-up. They can also be used with crystals when not operating close to the maximum frequency of the device, and if frequency stability at start-up is not important for the application.
Power-save
(1)
(1)
(2)
(2)
(2)
Additional Delay
from Reset
(VCC = 5.0V) Recommended Usage
4.1 ms
65 ms
–
4.1 ms
65 ms
Ceramic resonator, fast
rising power
Ceramic resonator, slowly
rising power
Ceramic resonator, BOD
enabled
Ceramic resonator, fast
rising power
Ceramic resonator, slowly
rising power
Crystal Oscillator, BOD
enabled
Crystal Oscillator, fast
rising power
Crystal Oscillator, slowly
rising power
8.5 Low-frequency Crystal Oscillator
To use a 32.768 kHz watch crystal as the clock source for the device, the Low-frequency crystal
Oscillator must be selected by setting the CKSEL Fuses to “1001”. The crystal should be connected as shown in Figure 8-2. By programming the CKOPT Fuse, the user can enable internal
capacitors on XTAL1 and XTAL2, thereby removing the need for external capacitors. The internal capacitors have a nominal value of 36 pF.
When this Oscillator is selected, start-up times are determined by the SUT Fuses as shown in
Table 8-4.
Table 8-4. Start-up Times for the Low-frequency Crystal Oscillator Clock Selection
Start-up Time from
Power-down and
SUT1:0
00 1K CK
01 1K CK
10 32K CK 65 ms Stable frequency at start-up
11 Reserved
Note: 1. These options should only be used if frequency stability at start-up is not important for the
Power-save
application.
Additional Delay from
Reset
(VCC = 5.0V) Recommended Usage
(1)
(1)
4.1 ms Fast rising power or BOD enabled
65 ms Slowly rising power
8160C–AVR–07/09
40
Page 41
8.6 External RC Oscillator
XTAL2
XTAL1
GND
C
R
V
CC
NC
For timing insensitive applications, the external RC configuration shown in Figure 8-4 can be
used. The frequency is roughly estimated by the equation f = 1/(3RC). C should be at least 22
pF. By programming the CKOPT Fuse, the user can enable an internal 36 pF capacitor between
XTAL1 and GND, thereby removing the need for an external capacitor.
Figure 8-4. External RC Configuration
The Oscillator can operate in four different modes, each optimized for a specific frequency
range. The operating mode is selected by the fuses CKSEL3:0 as shown in Table 8-5.
ATmega64A
Table 8-5. External RC Oscillator Operating Modes
CKSEL3:0 Frequency Range (MHz)
0101 0.1 - 0.9
0110 0.9 - 3.0
0111 3.0 - 8.0
1000 8.0 - 12.0
When this Oscillator is selected, start-up times are determined by the SUT Fuses as shown in
Table 8-6.
Table 8-6. Start-up Times for the External RC Oscillator Clock Selection
Start-up Time from
Power-down and
SUT1:0
00 18 CK – BOD enabled
01 18 CK 4.1 ms Fast rising power
10 18 CK 65 ms Slowly rising power
11 6 CK
Note: 1. This option should not be used when operating close to the maximum frequency of the device.
Power-save
(1)
Additional Delay from
Reset
(VCC = 5.0V) Recommended Usage
4.1 ms Fast rising power or BOD enabled
8160C–AVR–07/09
41
Page 42
8.7 Calibrated Internal RC Oscillator
The calibrated internal RC Oscillator provides a fixed 1.0, 2.0, 4.0, or 8.0 MHz clock. All frequencies are nominal values at 5V and 25⋅C. This clock may be selected as the system clock by
programming the CKSEL Fuses as shown in Table 8-7. If selected, it will operate with no external components. The CKOPT Fuse should always be unprogrammed when using this clock
option. During reset, hardware loads the calibration byte into the OSCCAL Register and thereby
automatically calibrates the RC Oscillator. At 5V, 25⋅C and 1.0 MHz Oscillator frequency
selected, this calibration gives a frequency within ± 3% of the nominal frequency. Using run-time
calibration methods as described in application notes available at www.atmel.com/avr it is possible to achieve ± 1% accuracy at any given V
as the chip clock, the Watchdog Oscillator will still be used for the Watchdog Timer and for the
Reset Time-out. For more information on the preprogrammed calibration value, see the section
“Calibration Byte” on page 298.
Table 8-7. Internal Calibrated RC Oscillator Operating Modes
CKSEL3:0 Nominal Frequency (MHz)
(1)
0001
0010 2.0
0011 4.0
0100 8.0
ATmega64A
and Temperature. When this Oscillator is used
CC
1.0
8.8 External Clock
Note: 1. The device is shipped with this option selected.
When this Oscillator is selected, start-up times are determined by the SUT Fuses as shown in
Table 8-8. XTAL1 and XTAL2 should be left unconnected (NC).
Table 8-8. Start-up Times for the Internal Calibrated RC Oscillator Clock Selection
Start-up Time from Power-
SUT1:0
00 6 CK – BOD enabled
01 6 CK 4.1 ms Fast rising power
(1)
10
11 Reserved
Note: 1. The device is shipped with this option selected.
down and Power-save
6 CK 65 ms Slowly rising power
Additional Delay from
Reset (VCC = 5.0V) Recommended Usage
To drive the device from an external clock source, XTAL1 should be driven as shown in Figure
8-5. To run the device on an external clock, the CKSEL Fuses must be programmed to “0000”.
By programming the CKOPT Fuse, the user can enable an internal 36 pF capacitor between
XTAL1 and GND.
8160C–AVR–07/09
42
Page 43
ATmega64A
EXTERNAL
CLOCK
SIGNAL
Figure 8-5. External Clock Drive Configuration
When this clock source is selected, start-up times are determined by the SUT Fuses as shown in
Table 8-9.
Table 8-9. Start-up Times for the External Clock Selection
SUT1:0
00 6 CK – BOD enabled
01 6 CK 4.1 ms Fast rising power
10 6 CK 65 ms Slowly rising power
11 Reserved
When applying an external clock, it is required to avoid sudden changes in the applied clock frequency to ensure stable operation of the MCU. A variation in frequency of more than 2% from
one clock cycle to the next can lead to unpredictable behavior. It is required to ensure that the
MCU is kept in Reset during such changes in the clock frequency.
8.9 Timer/Counter Oscillator
For AVR microcontrollers with Timer/Counter Oscillator pins (TOSC1 and TOSC2), the crystal is
connected directly between the pins. No external capacitors are needed. The Oscillator is optimized for use with a 32.768 kHz watch crystal. Applying an external clock source to TOSC1 is
not recommended.
Note: The Timer/Counter Oscillator uses the same type of crystal oscillator as Low-Frequency Oscillator
and the internal capacitors have the same nominal value of 36 pF.
Start-up Time from Power-
down and Power-save
Additional Delay from
Reset (VCC = 5.0V) Recommended Usage
8160C–AVR–07/09
43
Page 44
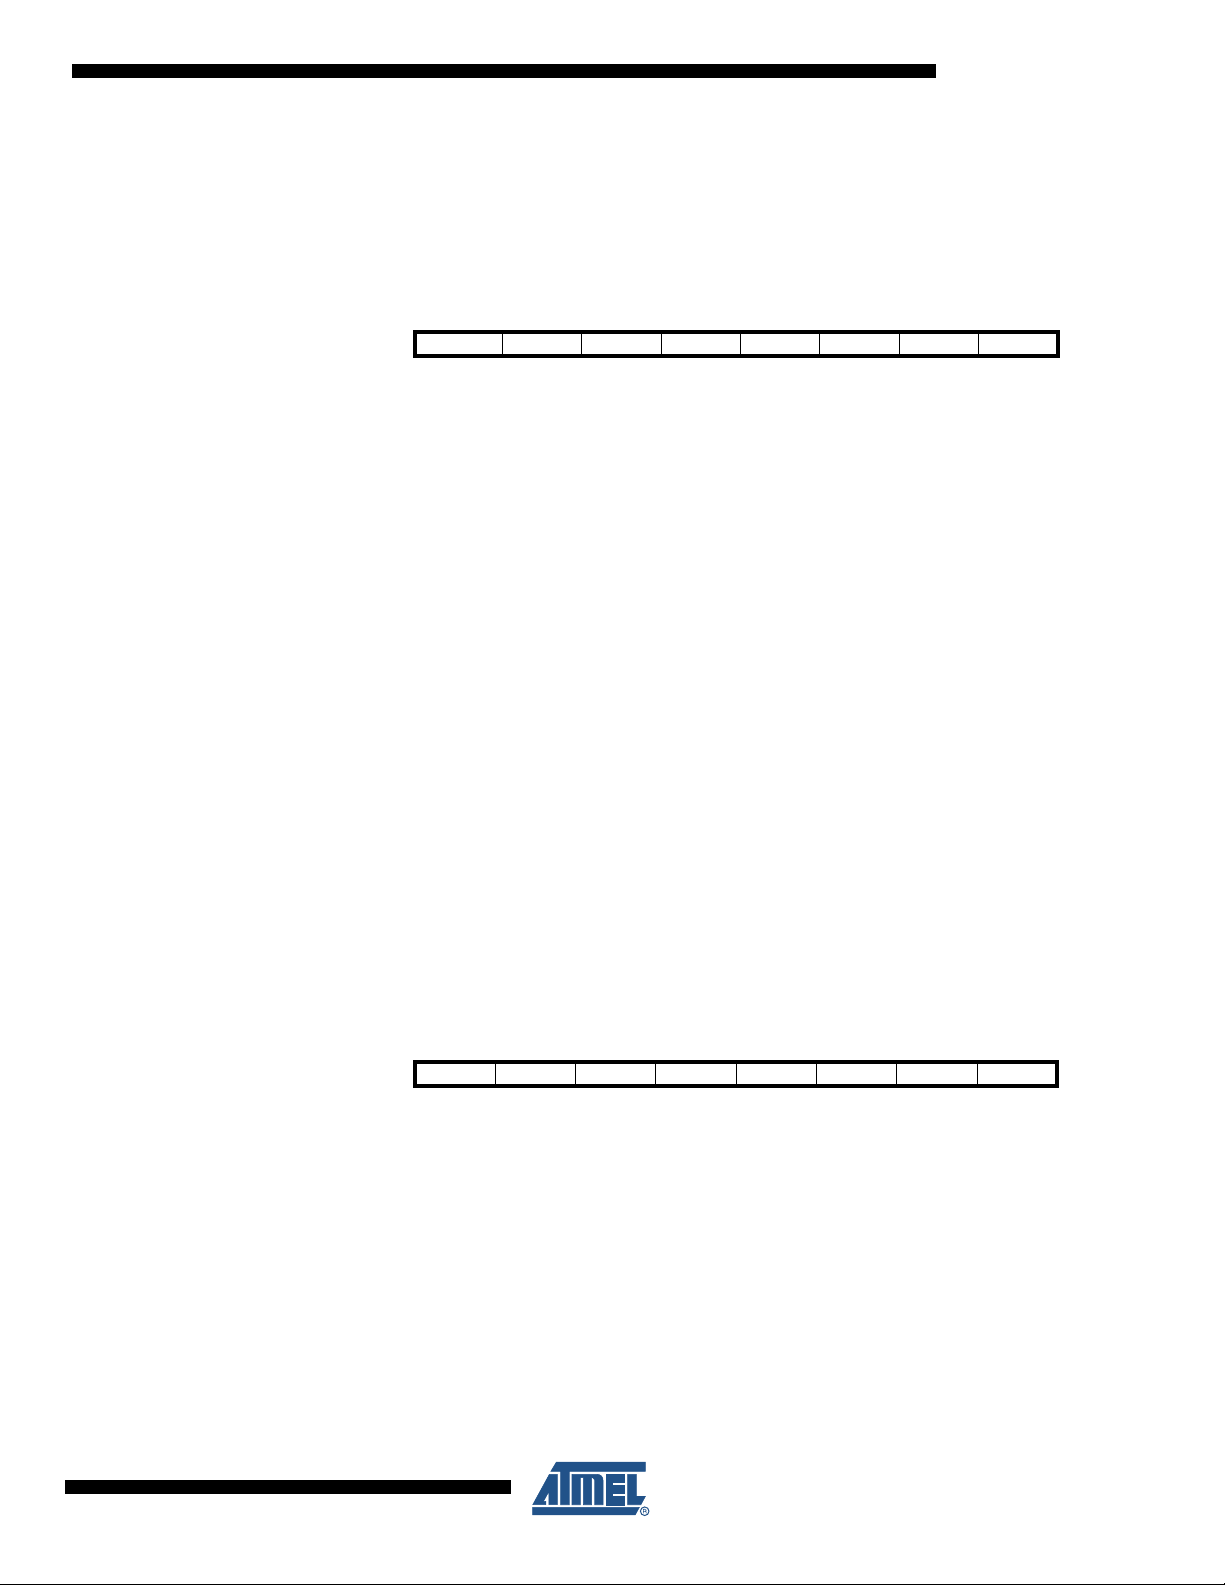
8.10 Register Descriprion
f
CLK
Source clock
129 d–
----------------------------------=
8.10.1 XDIV – XTAL Divide Control Register
The XTAL Divide Control Register is used to divide the source clock frequency by a number in
the range 2 - 129. This feature can be used to decrease power consumption when the requirement for processing power is low.
Bit 7 6543210
0x3C (0x5C) XDIVEN XDIV6 XDIV5 XDIV4 XDIV3 XDIV2 XDIV1 XDIV0 XDIV
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
• Bit 7 – XDIVEN: XTAL Divide Enable
When the XDIVEN bit is written one, the clock frequency of the CPU and all peripherals (clk
clk
, clk
ADC
can be written run-time to vary the clock frequency as suitable to the application.
• Bits 6:0 – XDIV6:XDIV0: XTAL Divide Select Bits 6 - 0
These bits define the division factor that applies when the XDIVEN bit is set (one). If the value of
these bits is denoted d, the following formula defines the resulting CPU and peripherals clock
frequency f
CPU
clk
, clk
:
FLASH
ATmega64A
I/O
) is divided by the factor defined by the setting of XDIV6 - XDIV0. This bit
,
The value of these bits can only be changed when XDIVEN is zero. When XDIVEN is written to
one, the value written simultaneously into XDIV6:XDIV0 is taken as the division factor. When
XDIVEN is written to zero, the value written simultaneously into XDIV6:XDIV0 is rejected. As the
divider divides the master clock input to the MCU, the speed of all peripherals is reduced when a
division factor is used.
Note: When the system clock is divided, Timer/Counter0 can be used with Asynchronous clock only. The
frequency of the asynchronous clock must be lower than 1/4th of the frequency of the scaled down
Source clock. Otherwise, interrupts may be lost, and accessing the Timer/Counter0 registers may
fail.
8.10.2 OSCCAL – Oscillator Calibration Register
Bit 76543210
(0x6F) CAL7 CAL6 CAL5 CAL4 CAL3 CAL2 CAL1 CAL0 OSCCAL
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value Device Specific Calibration Value
Note: 1. The OSCCAL Register is not available in ATmega103 compatibility mode.
• Bits 7:0 – CAL7:0: Oscillator Calibration Value
Writing the calibration byte to this address will trim the internal Oscillator to remove process variations from the Oscillator frequency. During Reset, the 1 MHz calibration value which is located
in the signature row high byte (address 0x00) is automatically loaded into the OSCCAL Register.
If the internal RC is used at other frequencies, the calibration values must be loaded manually.
This can be done by first reading the signature row by a programmer, and then store the calibration values in the Flash or EEPROM. Then the value can be read by software and loaded into
the OSCCAL Register. When OSCCAL is zero, the lowest available frequency is chosen. Writing
non-zero values to this register will increase the frequency of the internal Oscillator. Writing
(1)
8160C–AVR–07/09
44
Page 45
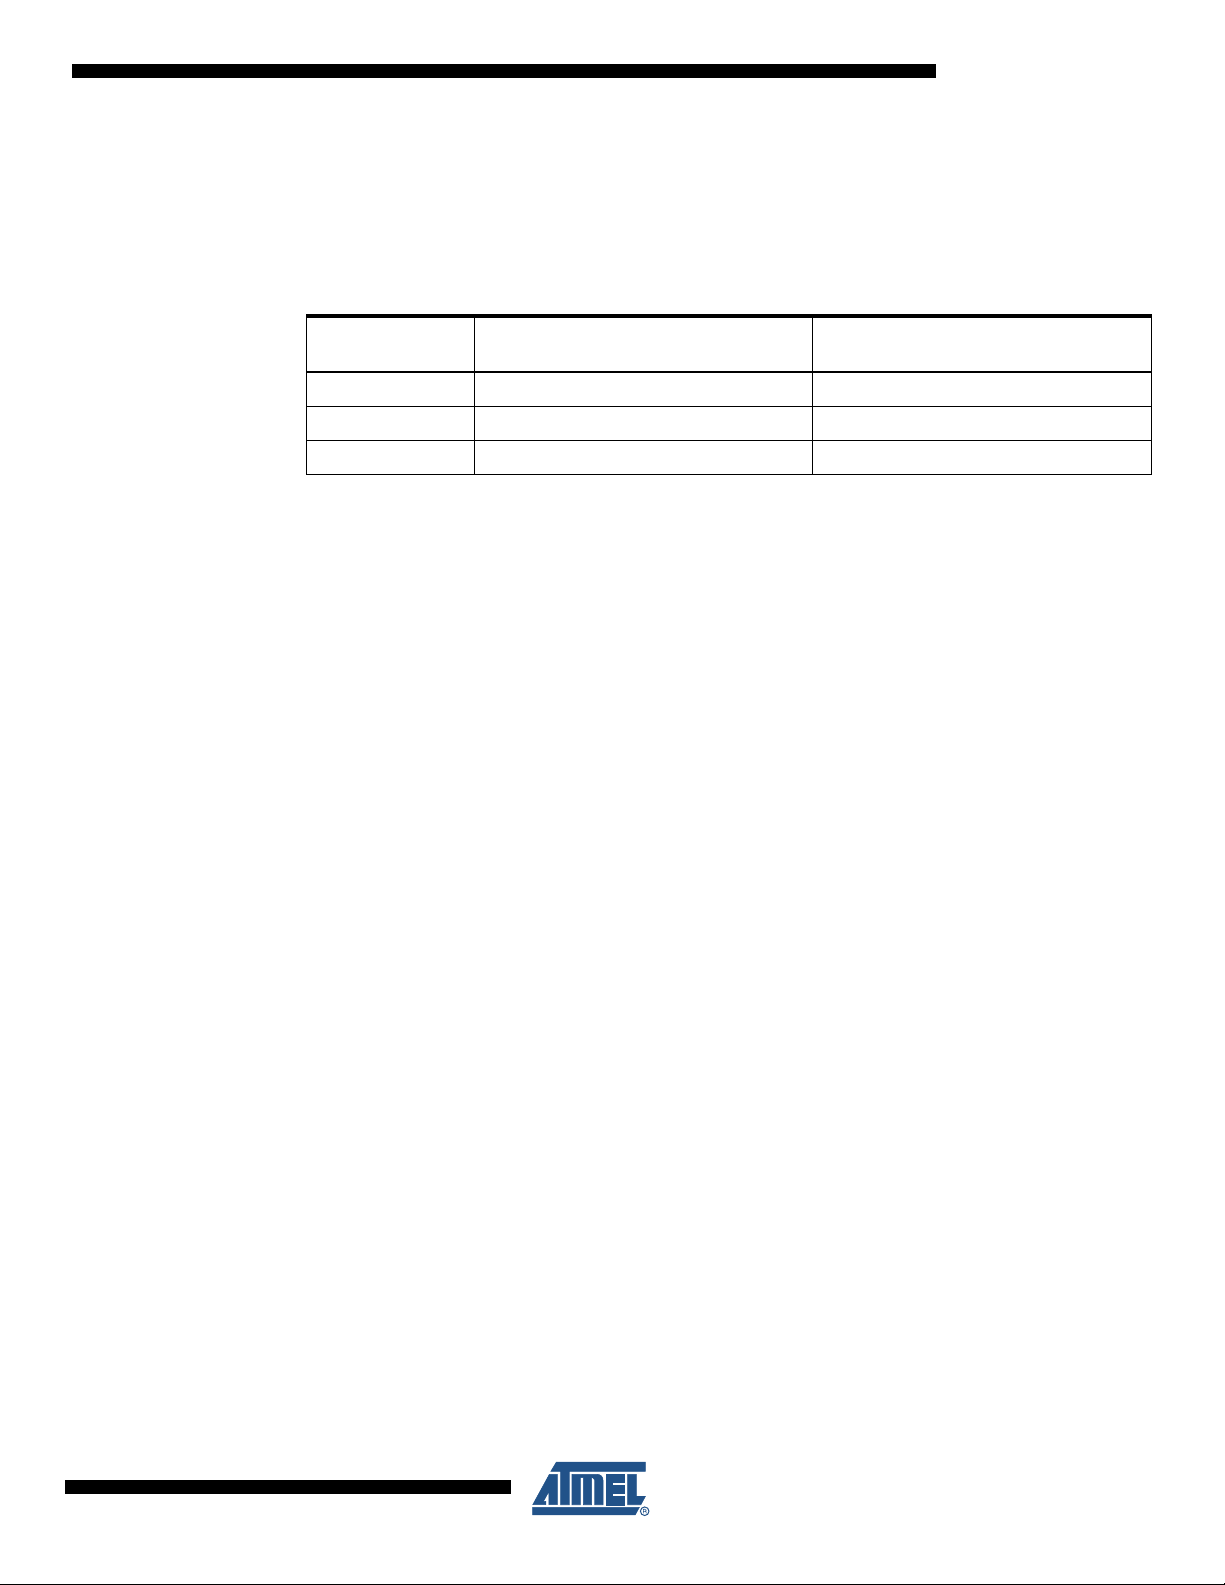
ATmega64A
0xFF to the register gives the highest available frequency. The calibrated Oscillator is used to
time EEPROM and Flash access. If EEPROM or Flash is written, do not calibrate to more than
10% above the nominal frequency. Otherwise, the EEPROM or Flash write may fail. Note that
the Oscillator is intended for calibration to 1.0, 2.0, 4.0, or 8.0 MHz. Tuning to other values is not
guaranteed, as indicated in Table 8-10.
Table 8-10. Internal RC Oscillator Frequency Range
Min Frequency in Percentage of
OSCCAL Value
0x00 50 100
0x7F 75 150
0xFF 100 200
Nominal Frequency (%)
Max Frequency in Percentage of
Nominal Frequency (%)
8160C–AVR–07/09
45
Page 46
9. Power Management and Sleep Modes
Sleep modes enable the application to shut down unused modules in the MCU, thereby saving
power. The AVR provides various sleep modes allowing the user to tailor the power consumption to the application’s requirements.
To enter any of the six sleep modes, the SE-bit in MCUCR must be written to logic one and a
SLEEP instruction must be executed. The SM2, SM1, and SM0 bits in the MCUCR Register
select which sleep mode (Idle, ADC Noise Reduction, Power-down, Power-save, Standby, or
Extended Standby) will be activated by the SLEEP instruction. See Table 9-2 for a summary. If
an enabled interrupt occurs while the MCU is in a sleep mode, the MCU wakes up. The MCU is
then halted for four cycles in addition to the start-up time, it executes the interrupt routine, and
resumes execution from the instruction following SLEEP. The contents of the Register File and
SRAM are unaltered when the device wakes up from sleep. If a reset occurs during sleep mode,
the MCU wakes up and executes from the Reset Vector.
Figure 8-1 on page 37 presents the different clock systems in the ATmega64A, and their distri-
bution. This figure is helpful in selecting an appropriate sleep mode.
ATmega64A
9.1 Idle Mode
When the SM2:0 bits are written to 000, the SLEEP instruction makes the MCU enter Idle mode,
stopping the CPU but allowing SPI, USART, Analog Comparator, ADC, Two-wire Serial Interface, Timer/Counters, Watchdog, and the interrupt system to continue operating. This sleep
mode basically halts clk
Idle mode enables the MCU to wake up from external triggered interrupts as well as internal
ones like the Timer Overflow and USART Transmit Complete interrupts. If wake-up from the
Analog Comparator interrupt is not required, the Analog Comparator can be powered down by
setting the ACD bit in the Analog Comparator Control and Status Register – ACSR. This will
reduce power consumption in Idle mode. If the ADC is enabled, a conversion starts automatically when this mode is entered.
9.2 ADC Noise Reduction Mode
When the SM2:0 bits are written to 001, the SLEEP instruction makes the MCU enter ADC
Noise Reduction mode, stopping the CPU but allowing the ADC, the external interrupts, the
Two-wire Serial Interface address watch, Timer/Counter0 and the Watchdog to continue operating (if enabled). This sleep mode basically halts clk
other clocks to run.
This improves the noise environment for the ADC, enabling higher resolution measurements. If
the ADC is enabled, a conversion starts automatically when this mode is entered. Apart form the
ADC Conversion Complete interrupt, only an External Reset, a Watchdog Reset, a Brown-out
Reset, a Two-wire Serial Interface address match interrupt, a Timer/Counter0 interrupt, an
SPM/EEPROM ready interrupt, an external level interrupt on INT7:4, or an External Interrupt on
INT3:0 can wake up the MCU from ADC Noise Reduction mode.
CPU
and clk
, while allowing the other clocks to run.
FLASH
I/O
, clk
, and clk-
CPU
, while allowing the
FLASH
8160C–AVR–07/09
46
Page 47
9.3 Power-down Mode
When the SM2:0 bits are written to 010, the SLEEP instruction makes the MCU enter Powerdown mode. In this mode, the external Oscillator is stopped, while the external interrupts, the
Two-wire Serial Interface address watch, and the Watchdog continue operating (if enabled).
Only an External Reset, a Watchdog Reset, a Brown-out Reset, a Two-wire Serial Interface
address match interrupt, an external level interrupt on INT7:4, or an External Interrupt on INT3:0
can wake up the MCU. This sleep mode basically halts all generated clocks, allowing operation
of asynchronous modules only.
Note that if a level triggered interrupt is used for wake-up from Power-down mode, the changed
level must be held for some time to wake up the MCU. Refer to “8-bit Timer/Counter0 with PWM
and Asynchronous Operation” on page 92 for details.
When waking up from Power-down mode, there is a delay from the wake-up condition occurs
until the wake-up becomes effective. This allows the clock to restart and become stable after
having been stopped. The wake-up period is defined by the same CKSEL Fuses that define the
Reset Time-out period, as described in “Clock Sources” on page 38.
9.4 Power-save Mode
When the SM2:0 bits are written to 011, the SLEEP instruction makes the MCU enter Powersave mode. This mode is identical to Power-down, with one exception:
ATmega64A
If Timer/Counter0 is clocked asynchronously (i.e., the AS0 bit in ASSR is set), Timer/Counter0
will run during sleep. The device can wake up from either Timer Overflow or Output Compare
event from Timer/Counter0 if the corresponding Timer/Counter0 interrupt enable bits are set in
TIMSK, and the Global Interrupt Enable bit in SREG is set.
If the asynchronous timer is NOT clocked asynchronously, Power-down mode is recommended
instead of Power-save mode because the contents of the registers in the asynchronous timer
should be considered undefined after wake-up in Power-save mode if AS0 is 0.
This sleep mode basically halts all clocks except clk
modules, including Timer/Counter0 if clocked asynchronously.
9.5 Standby Mode
When the SM2:0 bits are 110 and an external crystal/resonator clock option is selected, the
SLEEP instruction makes the MCU enter Standby mode. This mode is identical to Power-down
with the exception that the Oscillator is kept running. From Standby mode, the device wakes up
in six clock cycles.
9.6 Extended Standby Mode
When the SM2:0 bits are 111 and an external crystal/resonator clock option is selected, the
SLEEP instruction makes the MCU enter Extended Standby mode. This mode is identical to
Power-save mode with the exception that the Oscillator is kept running. From Extended Standby
mode, the device wakes up in six clock cycles.
, allowing operation only of asynchronous
ASY
8160C–AVR–07/09
47
Page 48
Table 9-1. Active Clock Domains and Wake Up Sources in the Different Sleep Modes
Active Clock Domains Oscillators Wake Up Sources
ATmega64A
Sleep
Mode
CPU
clk
FLASH
clk
IO
clk
ADC
clk
ASY
clk
Main
Clock
Source
Enabled
Idle X X X X X
ADC
Noise
XX X X
Reduction
Powerdown
Powersave
Standby
Extended
Standby
(1)
(1)
(2)
X
XX
(2)
X
XX
Notes: 1. External Crystal or resonator selected as clock source.
2. If AS
0 bit in ASSR is set.
3. Only INT3:0 or level interrupt INT7:4.
9.7 Minimizing Power Consumption
There are several issues to consider when trying to minimize the power consumption in an AVR
controlled system. In general, sleep modes should be used as much as possible, and the sleep
mode should be selected so that as few as possible of the device’s functions are operating. All
functions not needed should be disabled. In particular, the following modules may need special
consideration when trying to achieve the lowest possible power consumption.
Timer
Osc
(2)
(2)
(2)
X
(2)
EnabledIN
TWI
Address
Match
Timer0
SPM/
EEPROM
Ready
A
XX X XXX
(3)
X
(3)
X
(3)
X
(3)
(3)
X
XX XX
X
XX
(2)
X
XX
(2)
Other
I/O
9.7.1 Analog to Digital Converter
If enabled, the ADC will be enabled in all sleep modes. To save power, the ADC should be disabled before entering any sleep mode. When the ADC is turned off and on again, the next
conversion will be an extended conversion. Refer to “Analog to Digital Converter” on page 233
for details on ADC operation.
9.7.2 Analog Comparator
When entering Idle mode, the Analog Comparator should be disabled if not used. When entering
ADC Noise Reduction mode, the Analog Comparator should be disabled. In the other sleep
modes, the Analog Comparator is automatically disabled. However, if the Analog Comparator is
set up to use the internal voltage reference as input, the Analog Comparator should be disabled
in all sleep modes. Otherwise, the internal voltage reference will be enabled, independent of
sleep mode. Refer to “Analog Comparator” on page 230 for details on how to configure the Analog Comparator.
9.7.3 Brown-out Detector
If the Brown-out Detector is not needed in the application, this module should be turned off. If the
Brown-out Detector is enabled by the BODEN Fuse, it will be enabled in all sleep modes, and
8160C–AVR–07/09
48
Page 49
hence, always consume power. In the deeper sleep modes, this will contribute significantly to
the total current consumption. Refer to “Brown-out Detector” on page 48 for details on how to
configure the Brown-out Detector.
9.7.4 Internal Voltage Reference
The internal voltage reference will be enabled when needed by the Brown-out Detector, the Analog Comparator or the ADC. If these modules are disabled as described in the sections above,
the internal voltage reference will be disabled and it will not be consuming power. When turned
on again, the user must allow the reference to start up before the output is used. If the reference
is kept on in sleep mode, the output can be used immediately. Refer to “Internal Voltage Refer-
ence” on page 55 for details on the start-up time.
9.7.5 Watchdog Timer
If the Watchdog Timer is not needed in the application, this module should be turned off. If the
Watchdog Timer is enabled, it will be enabled in all sleep modes, and hence, always consume
power. In the deeper sleep modes, this will contribute significantly to the total current consumption. Refer to “Watchdog Timer” on page 55 for details on how to configure the Watchdog Timer.
9.7.6 Port Pins
When entering a sleep mode, all port pins should be configured to use minimum power. The
most important thing is then to ensure that no pins drive resistive loads. In sleep modes where
the both the I/O clock (clk
device will be disabled. This ensures that no power is consumed by the input logic when not
needed. In some cases, the input logic is needed for detecting wake-up conditions, and it will
then be enabled. Refer to the section “Digital Input Enable and Sleep Modes” on page 72 for
details on which pins are enabled. If the input buffer is enabled and the input signal is left floating
or have an analog signal level close to V
) and the ADC clock (clk
I/O
/2, the input buffer will use excessive power.
CC
ATmega64A
) are stopped, the input buffers of the
ADC
9.7.7 JTAG Interface and On-chip Debug System
If the On-chip debug system is enabled by the OCDEN Fuse and the chip enter Power down or
Power save sleep mode, the main clock source remains enabled. In these sleep modes, this will
contribute significantly to the total current consumption. There are three alternative ways to
avoid this:
• Disable OCDEN Fuse.
• Disable JTAGEN Fuse.
• Write one to the JTD bit in MCUCSR.
The TDO pin is left floating when the JTAG interface is enabled while the JTAG TAP controller is
not shifting data. If the hardware connected to the TDO pin does not pull up the logic level,
power consumption will increase. Note that the TDI pin for the next device in the scan chain contains a pull-up that avoids this problem. Writing the JTD bit in the MCUCSR register to one or
leaving the JTAG fuse unprogrammed disables the JTAG interface.
8160C–AVR–07/09
49
Page 50

9.8 Register Description
9.8.1 MCUCR – MCU Control Register
The MCU Control Register contains control bits for power management.
Bit 76543210
0x35 (0x55)
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value00000000
• Bit 5 – SE: Sleep Enable
The SE bit must be written to logic one to make the MCU enter the sleep mode when the SLEEP
instruction is executed. To avoid the MCU entering the sleep mode unless it is the programmers
purpose, it is recommended to write the Sleep Enable (SE) bit to one just before the execution of
the SLEEP instruction and to clear it immediately after waking up.
• Bits 4:2 – SM2:0: Sleep Mode Select Bits 2, 1, and 0
These bits select between the six available sleep modes as shown in Table 9-2.
Table 9-2. Sleep Mode Select
SM2 SM1 SM0 Sleep Mode
SRE SRW10 SE SM1 SM0 SM2 IVSEL IVCE MCUCR
ATmega64A
000Idle
0 0 1 ADC Noise Reduction
010Power-down
011Power-save
100Reserved
101Reserved
110Standby
1 1 1 Extended Standby
Note: 1. Standby mode and Extended Standby mode are only available with external crystals or
resonators.
(1)
(1)
8160C–AVR–07/09
50
Page 51
10. System Control and Reset
10.0.1 Resetting the AVR
During Reset, all I/O Registers are set to their initial values, and the program starts execution
from the Reset Vector. The instruction placed at the Reset Vector must be a JMP – absolute
jump – instruction to the Reset handling routine. If the program never enables an interrupt
source, the Interrupt Vectors are not used, and regular program code can be placed at these
locations. This is also the case if the Reset Vector is in the Application section while the Interrupt
Vectors are in the Boot section or vice versa. The circuit diagram in Figure 10-1 shows the Reset
logic. Table 28-3 defines the electrical parameters of the Reset circuitry.
The I/O ports of the AVR are immediately Reset to their initial state when a reset source goes
active. This does not require any clock source to be running.
After all reset sources have gone inactive, a delay counter is invoked, stretching the Internal
Reset. This allows the power to reach a stable level before normal operation starts. The Timeout period of the delay counter is defined by the user through the CKSEL Fuses. The different
selections for the delay period are presented in “Clock Sources” on page 38.
ATmega64A
10.0.2 Reset Sources
The ATmega64A has five sources of reset:
• Power-on Reset. The MCU is reset when the supply voltage is below the Power-on Reset
threshold (V
• External Reset. The MCU is reset when a low level is present on the RESET
than the minimum pulse length.
• Watchdog Reset. The MCU is reset when the Watchdog Timer period expires and the
Watchdog is enabled.
• Brown-out Reset. The MCU is reset when the supply voltage V
Reset threshold (V
• JTAG AVR Reset. The MCU is reset as long as there is a logic one in the Reset Register, one
of the scan chains of the JTAG system. Refer to the section “IEEE 1149.1 (JTAG) Boundary-
scan” on page 259 for details.
POT
).
) and the Brown-out Detector is enabled.
BOT
pin for longer
is below the Brown-out
CC
8160C–AVR–07/09
51
Page 52
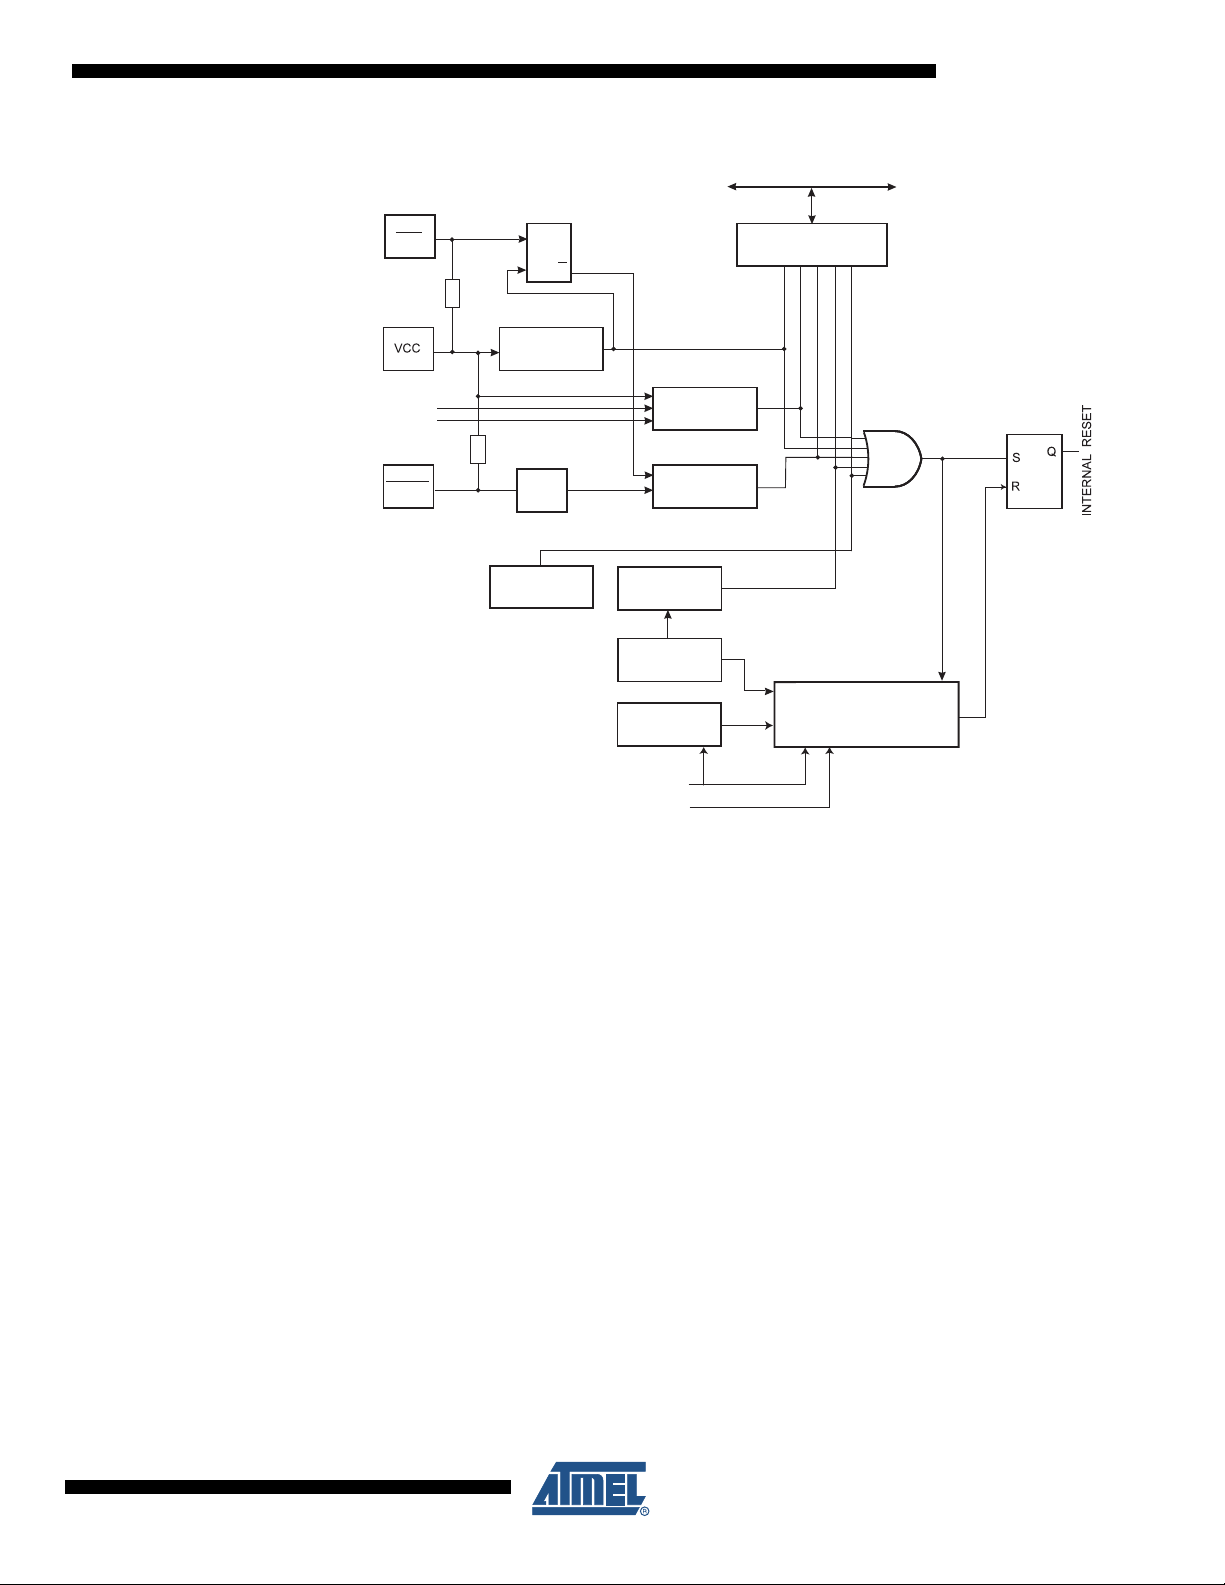
Figure 10-1. Reset Logic
MCU Control and Status
Register (MCUCSR)
Brown-Out
Reset Circuit
BODEN
BODLEVEL
Delay Counters
CKSEL[3:0]
CK
TIMEOUT
WDRF
BORF
EXTRF
PORF
DATA BU S
Clock
Generator
SPIKE
FILTER
Pull-up Resistor
JTRF
JTAG Reset
Register
Watchdog
Oscillator
SUT[1:0]
COUNTER RESET
Watchdog
Timer
RESET
Pull-up Resistor
PEN
Reset Circuit
L
DQ
Q
Power-On Reset
Circuit
ATmega64A
10.0.3 Power-on Reset
A Power-on Reset (POR) pulse is generated by an On-chip Detection circuit. The detection level
is defined in Table 28-3. The POR is activated whenever V
POR circuit can be used to trigger the Start-up Reset, as well as to detect a failure in supply
voltage.
A Power-on Reset (POR) circuit ensures that the device is reset from Power-on. Reaching the
Power-on Reset threshold voltage invokes the delay counter, which determines how long the
device is kept in RESET after V
when V
rise. The RESET signal is activated again, without any delay,
decreases below the detection level.
CC
CC
is below the detection level. The
CC
8160C–AVR–07/09
52
Page 53
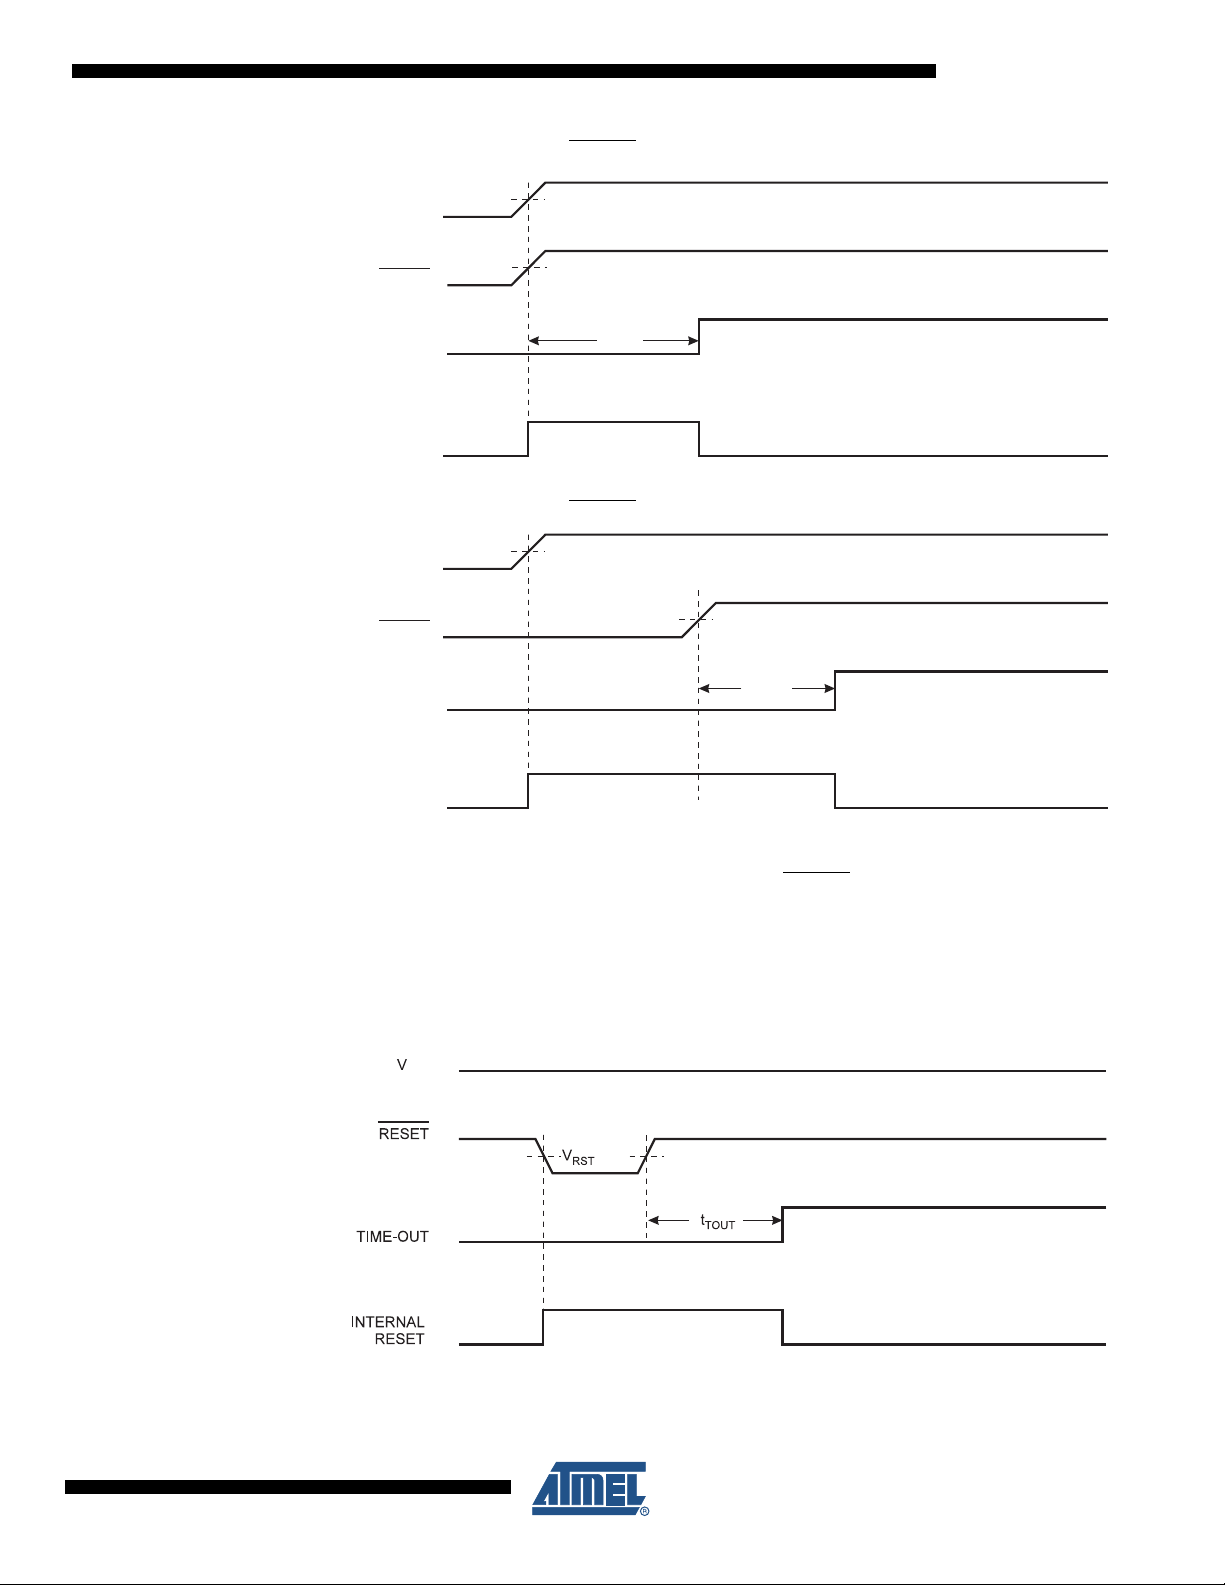
ATmega64A
CC
V
CC
CC
Figure 10-2. MCU Start-up, RESET Tied to V
V
V
RESET
TIME-OUT
INTERNAL
RESET
POT
V
RST
t
TOUT
CC
Figure 10-3. MCU Start-up, RESET Extended Externally
V
POT
V
RESET
TIME-OUT
RST
t
TOUT
10.0.4 External Reset
INTERNAL
RESET
An External Reset is generated by a low level on the RESET
pin. Reset pulses longer than the
minimum pulse width (see Table 28-3) will generate a reset, even if the clock is not running.
Shorter pulses are not guaranteed to generate a reset. When the applied signal reaches the
Reset Threshold Voltage – V
Time-out period t
has expired.
TOUT
on its positive edge, the delay counter starts the MCU after the
RST
Figure 10-4. External Reset during Operation
8160C–AVR–07/09
53
Page 54
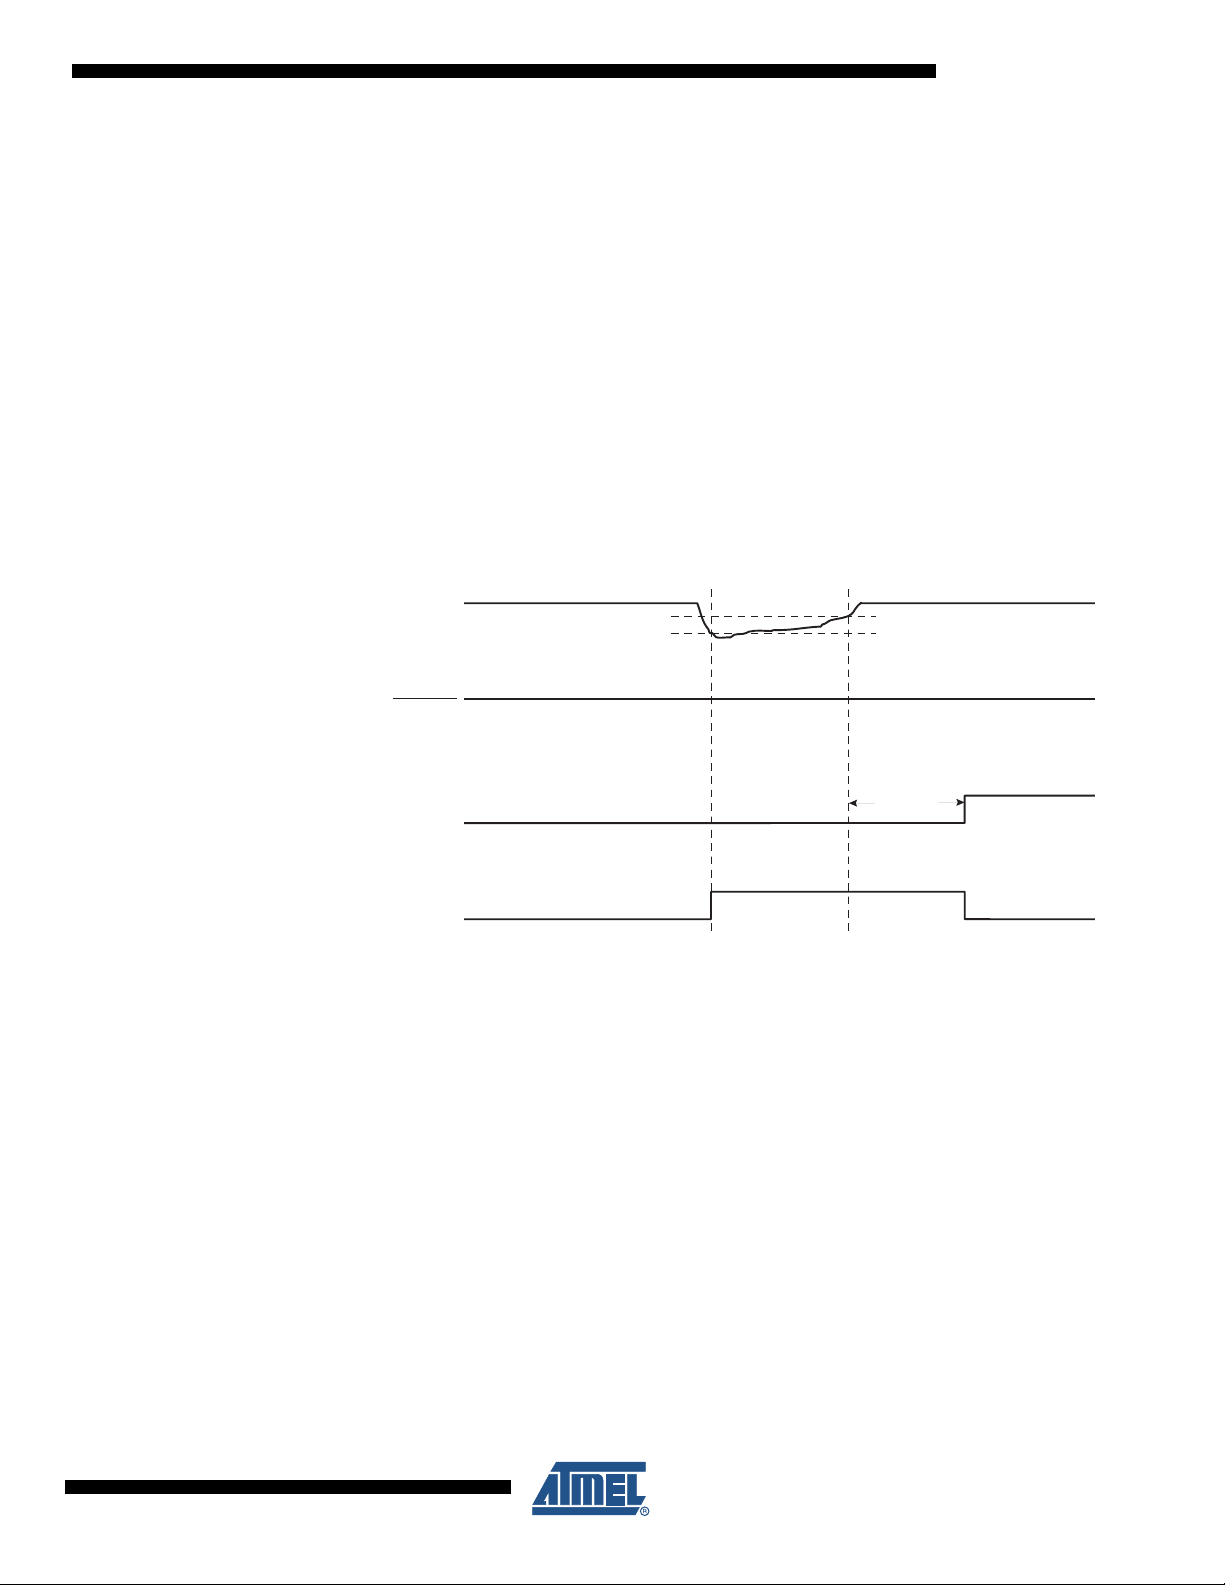
10.0.5 Brown-out Detection
V
CC
RESET
TIME-OUT
INTERNAL
RESET
V
BOT-
V
BOT+
t
TOUT
ATmega64A has an On-chip Brown-out Detection (BOD) circuit for monitoring the V
ing operation by comparing it to a fixed trigger level. The trigger level for the BOD can be
selected by the fuse BODLEVEL to be 2.7V (BODLEVEL unprogrammed), or 4.0V (BODLEVEL
programmed). The trigger level has a hysteresis to ensure spike free Brown-out Detection. The
hysteresis on the detection level should be interpreted as V
V
BOT
The BOD circuit can be enabled/disabled by the fuse BODEN. When the BOD is enabled
(BODEN programmed), and V
5), the Brown-out Reset is immediately activated. When V
(V
BOT+
expired.
ATmega64A
= V
BOT+
- V
HYST
/2.
decreases to a value below the trigger level (V
CC
increases above the trigger level
CC
in Figure 10-5), the delay counter starts the MCU after the Time-out period t
BOT
+ V
HYST
BOT-
level dur-
CC
/2 and V
BOT-
in Figure 10-
TOUT
=
has
10.0.6 Watchdog Reset
The BOD circuit will only detect a drop in V
ger than t
given in Table 28-3.
BOD
if the voltage stays below the trigger level for lon-
CC
Figure 10-5. Borwn-out Reset During Operation
When the Watchdog times out, it will generate a short reset pulse of one CK cycle duration. On
the falling edge of this pulse, the delay timer starts counting the Time-out period t
TOUT
. Refer to
page 55 for details on operation of the Watchdog Timer.
8160C–AVR–07/09
54
Page 55
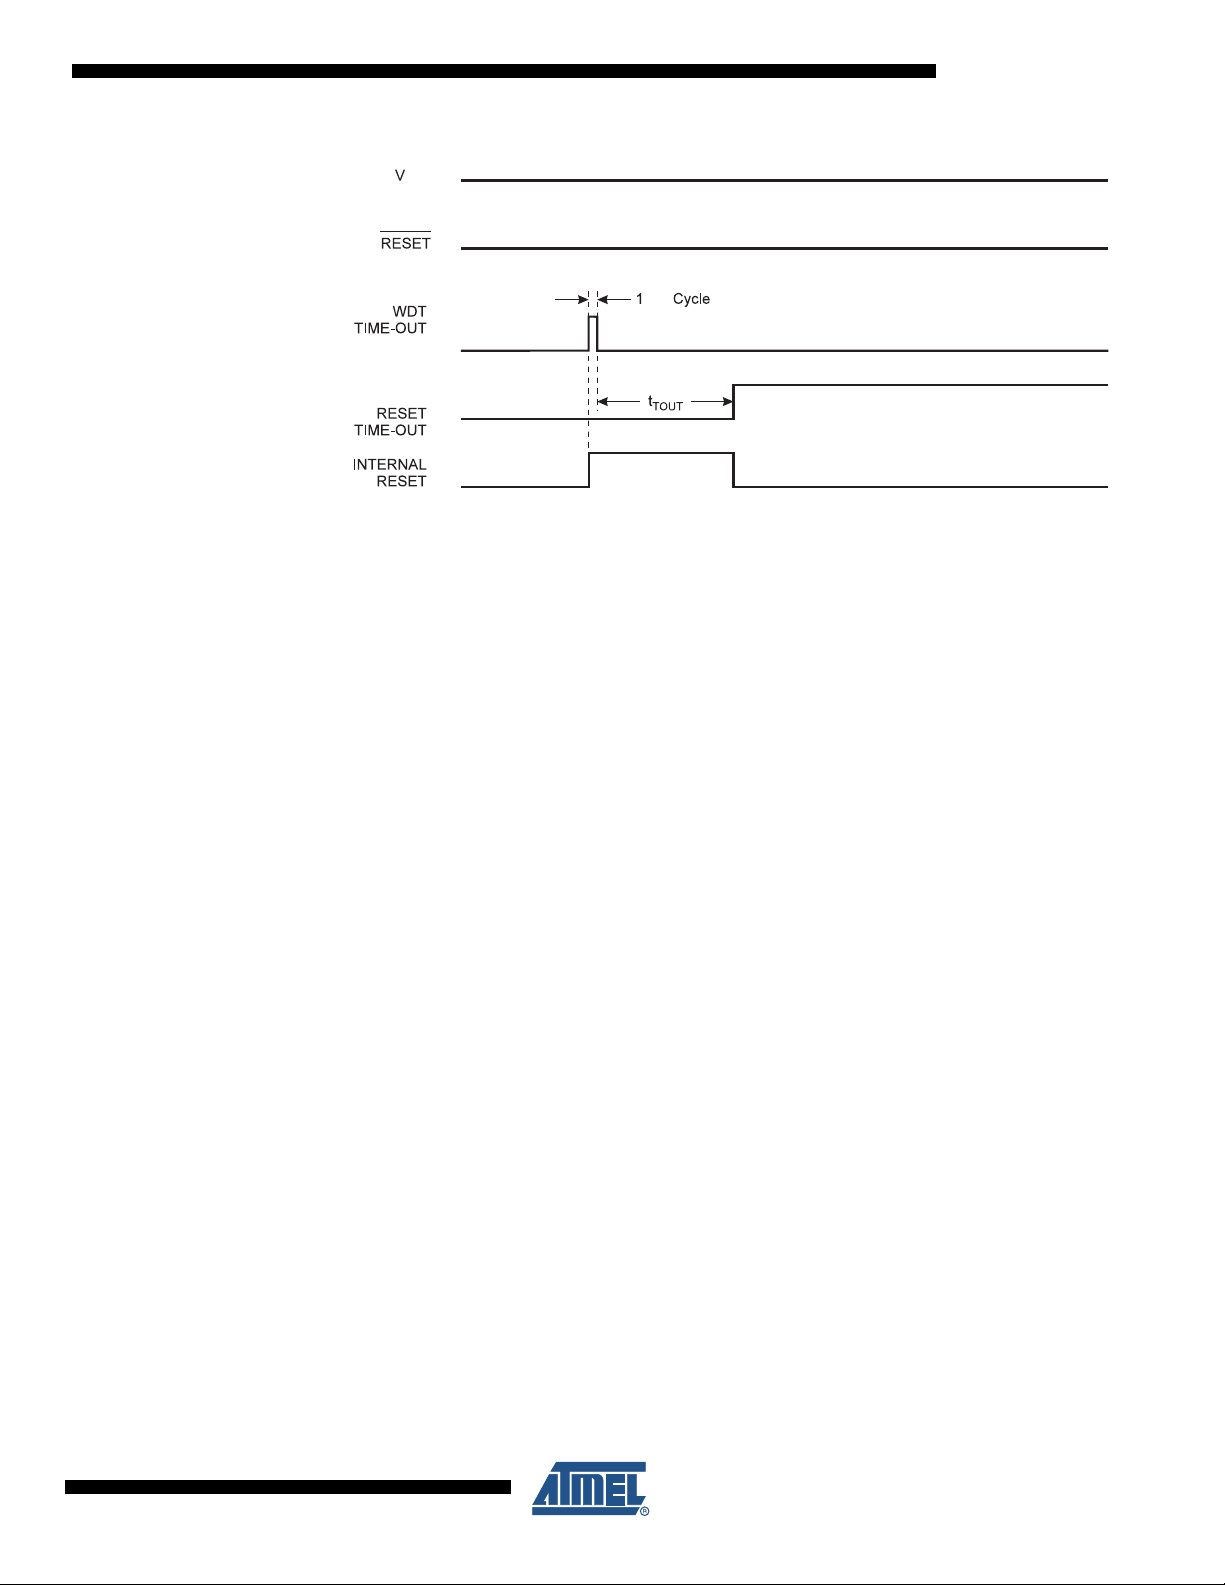
Figure 10-6. Watchdog Reset During Operation
CK
CC
10.1 Internal Voltage Reference
ATmega64A features an internal bandgap reference. This reference is used for Brown-out
Detection, and it can be used as an input to the Analog Comparator or the ADC. The 2.56V reference to the ADC is generated from the internal bandgap reference.
ATmega64A
10.1.1 Voltage Reference Enable Signals and Start-up Time
The voltage reference has a start-up time that may influence the way it should be used. The
start-up time is given in Table 28-3. To save power, the reference is not always turned on. The
reference is on during the following situations:
1. When the BOD is enabled (by programming the BODEN Fuse).
2. When the bandgap reference is connected to the Analog Comparator (by setting the
ACBG bit in ACSR).
3. When the ADC is enabled.
Thus, when the BOD is not enabled, after setting the ACBG bit or enabling the ADC, the user
must always allow the reference to start up before the output from the Analog Comparator or
ADC is used. To reduce power consumption in Power-down mode, the user can avoid the three
conditions above to ensure that the reference is turned off before entering Power-down mode.
10.2 Watchdog Timer
The Watchdog Timer is clocked from a separate On-chip Oscillator which runs at 1 Mhz. This is
the typical value at V
controlling the Watchdog Timer prescaler, the Watchdog Reset interval can be adjusted as
shown in Table 10-2 on page 58. The WDR – Watchdog Reset – instruction resets the Watchdog Timer. The Watchdog Timer is also reset when it is disabled and when a Chip Reset occurs.
Eight different clock cycle periods can be selected to determine the reset period. If the reset
period expires without another Watchdog Reset, the ATmega64A resets and executes from the
Reset Vector. For timing details on the Watchdog Reset, refer to “Watchdog Reset” on page 54.
To prevent unintentional disabling of the Watchdog or unintentional change of Time-out period,
three different safety levels are selected by the fuses M103C and WDTON as shown in Table
10-1. Safety level 0 corresponds to the setting in ATmega103. There is no restriction on
enabling the WDT in any of the safety levels. Refer to “Timed Sequences for Changing the Con-
figuration of the Watchdog Timer” on page 56 for details.
= 5V. See characterization data for typical values at other VCC levels. By
CC
8160C–AVR–07/09
55
Page 56
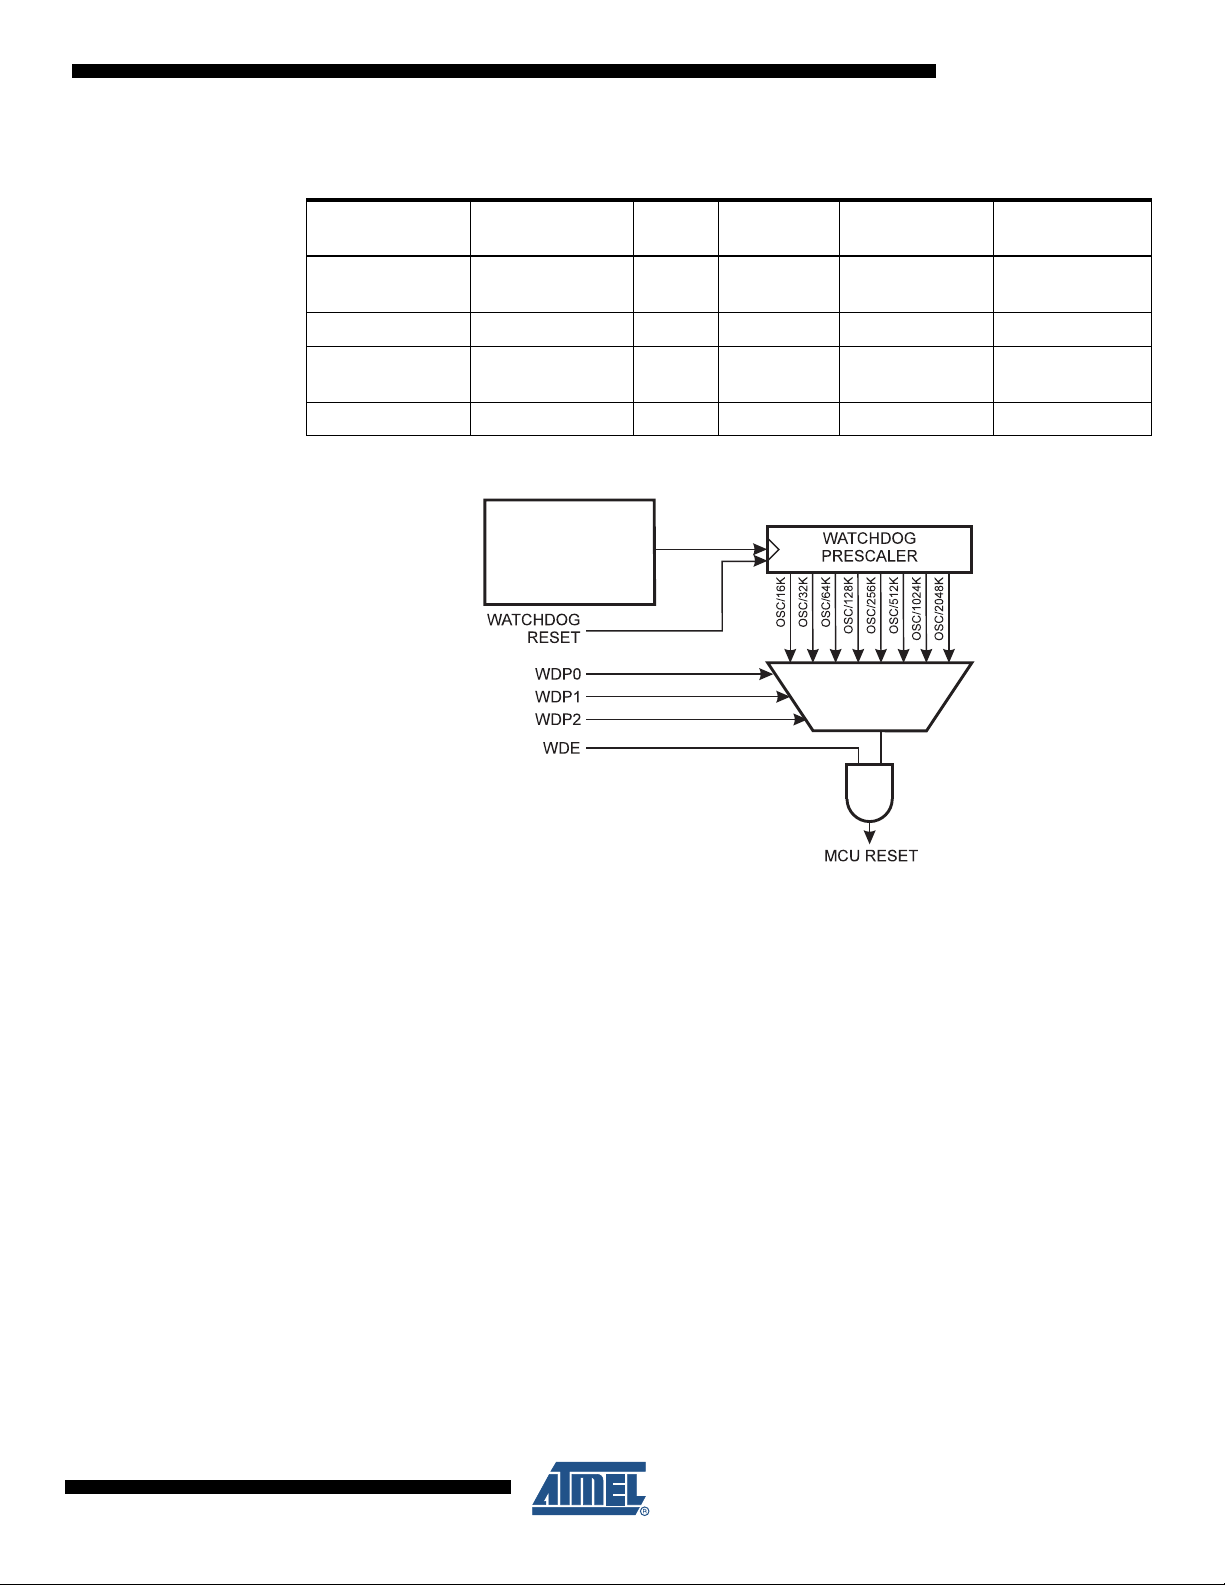
ATmega64A
WATCHDOG
OSCILLATOR
Table 10-1. WDT Configuration as a Function of the Fuse Settings of M103C and WDTON
Safety
M103C WDTON
Unprogrammed Unprogrammed 1 Disabled Timed
Unprogrammed Programmed 2 Enabled Always enabled Timed sequence
Programmed Unprogrammed 0 Disabled Timed
Programmed Programmed 2 Enabled Always enabled Timed sequence
Level
WDT Initial
State
How to Disable
the WDT
sequence
sequence
How to Change
Time-out
Timed sequence
No restriction
Figure 10-7. Watchdog Timer
10.3 Timed Sequences for Changing the Configuration of the Watchdog Timer
The sequence for changing configuration differs slightly between the three safety levels. Separate procedures are described for each level.
10.3.1 Safety Level 0
This mode is compatible with the Watchdog operation found in ATmega103. The Watchdog
Timer is initially disabled, but can be enabled by writing the WDE bit to 1 without any restriction.
The Time-out period can be changed at any time without restriction. To disable an enabled
Watchdog Timer, the procedure described on page 57 (WDE bit description) must be followed.
10.3.2 Safety Level 1
In this mode, the Watchdog Timer is initially disabled, but can be enabled by writing the WDE bit
to 1 without any restriction. A timed sequence is needed when changing the Watchdog Time-out
8160C–AVR–07/09
period or disabling an enabled Watchdog Timer. To disable an enabled Watchdog Timer, and/or
changing the Watchdog Time-out, the following procedure must be followed:
1. In the same operation, write a logic one to WDCE and WDE. A logic one must be written
to WDE regardless of the previous value of the WDE bit.
2. Within the next four clock cycles, in the same operation, write the WDE and WDP bits as
desired, but with the WDCE bit cleared.
56
Page 57
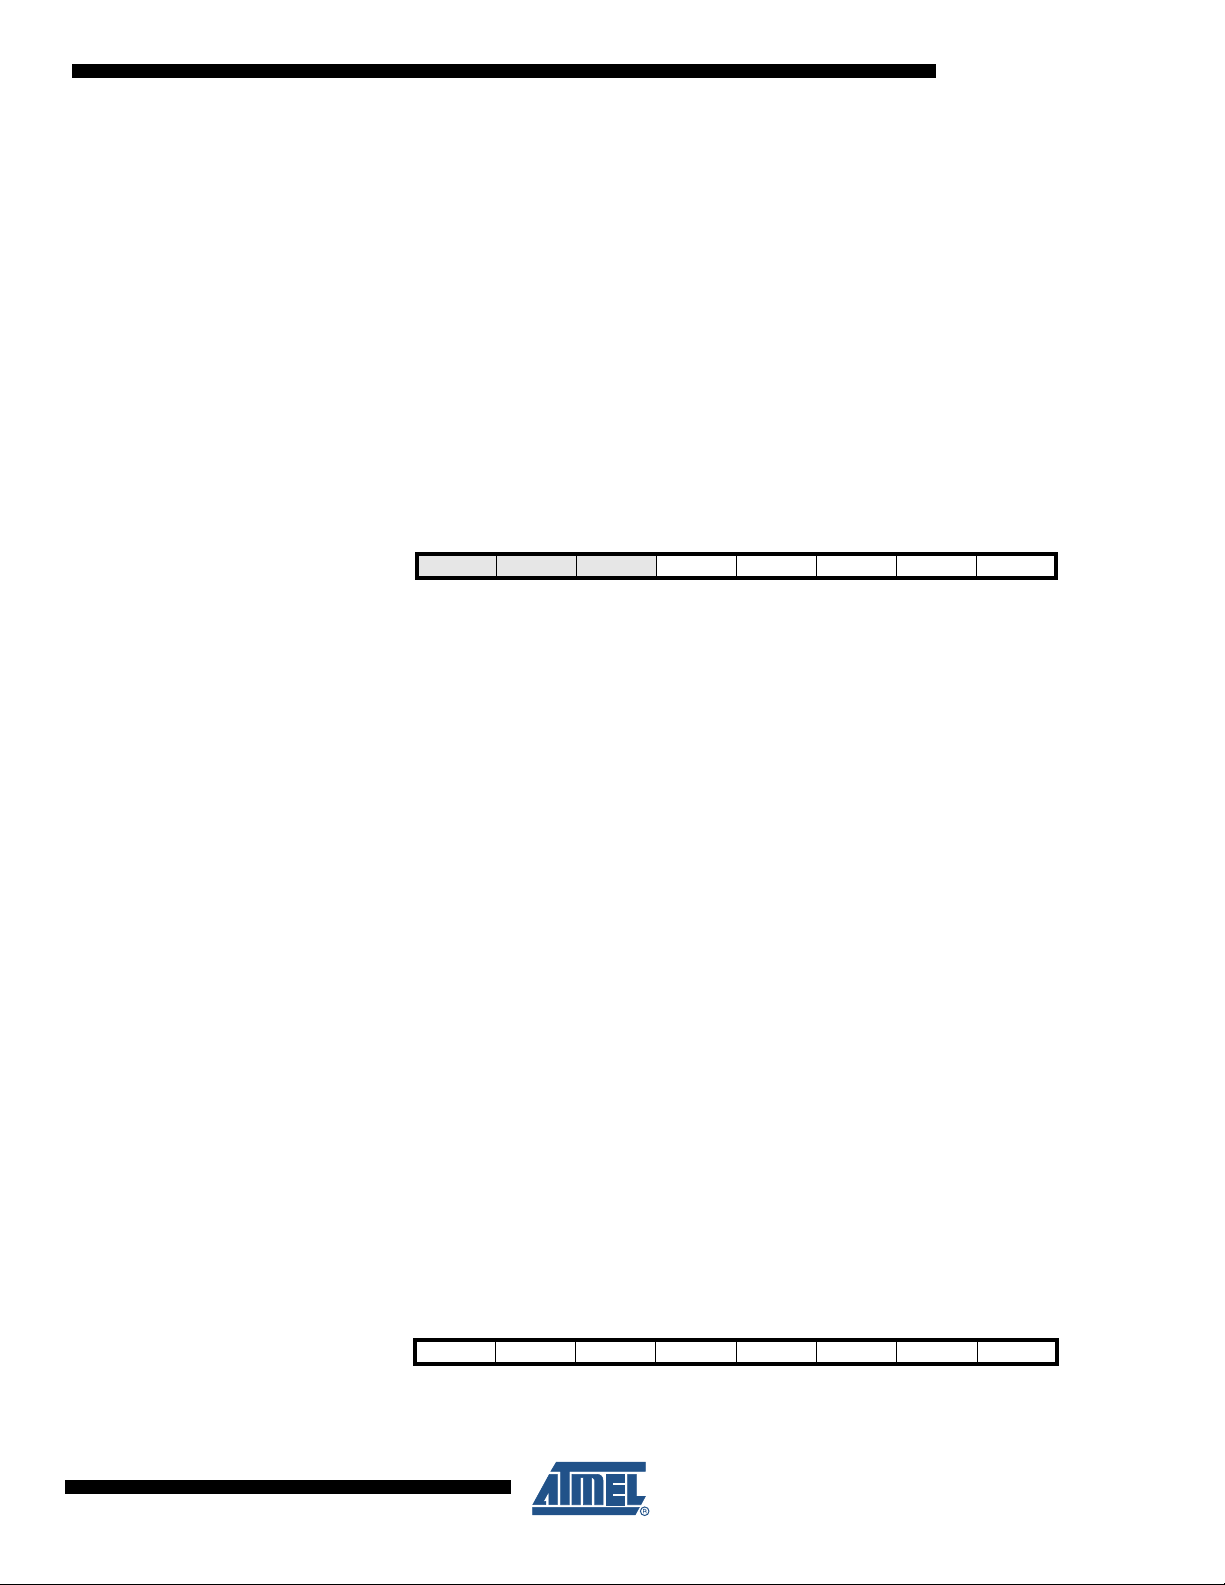
10.3.3 Safety Level 2
In this mode, the Watchdog Timer is always enabled, and the WDE bit will always read as one. A
timed sequence is needed when changing the Watchdog Time-out period. To change the
Watchdog Time-out, the following procedure must be followed:
1. In the same operation, write a logical one to WDCE and WDE. Even though the WDE
always is set, the WDE must be written to one to start the timed sequence.
2. Within the next four clock cycles, in the same operation, write the WDP bits as desired,
but with the WDCE bit cleared. The value written to the WDE bit is irrelevant.
10.4 Register Description
ATmega64A
10.4.1 MCUCSR – MCU Control and Status Register
The MCU Control and Status Register provides information on which reset source caused an
MCU Reset.
Bit 76543210
0x34 (0x54)
Read/Write R/W R R R/W R/W R/W R/W R/W
Initial Value 0 0 0 See Bit Description
Note: 1. Only EXTRF and PORF are available in mega103 compatibility mode.
JTD – – JTRF WDRF BORF EXTRF PORF MCUCSR
• Bit 4 – JTRF: JTAG Reset Flag
This bit is set if a reset is being caused by a logic one in the JTAG Reset Register selected by
the JTAG instruction AVR_RESET. This bit is reset by a Brown-out Reset, or by writing a logic
zero to the flag.
• Bit 3 – WDRF: Watchdog Reset Flag
This bit is set if a Watchdog Reset occurs. The bit is reset by a Power-on Reset, or by writing a
logic zero to the flag.
• Bit 2 – BORF: Brown-out Reset Flag
This bit is set if a Brown-out Reset occurs. The bit is reset by a Power-on Reset, or by writing a
logic zero to the flag.
(1)
• Bit 1 – EXTRF: External Reset Flag
This bit is set if an External Reset occurs. The bit is reset by a Power-on Reset, or by writing a
logic zero to the flag.
• Bit 0 – PORF: Power-on Reset Flag
This bit is set if a Power-on Reset occurs. The bit is reset only by writing a logic zero to the flag.
To make use of the reset flags to identify a reset condition, the user should read and then reset
the MCUCSR as early as possible in the program. If the register is cleared before another reset
occurs, the source of the reset can be found by examining the Reset Flags.
10.4.2 WDTCR – Watchdog Timer Control Register
Bit 76543210
0x21 (0x41) – – – WDCE WDE WDP2 WDP1 WDP0 WDTCR
Read/Write R R R R/W R/W R/W R/W R/W
Initial Value00000000
8160C–AVR–07/09
57
Page 58
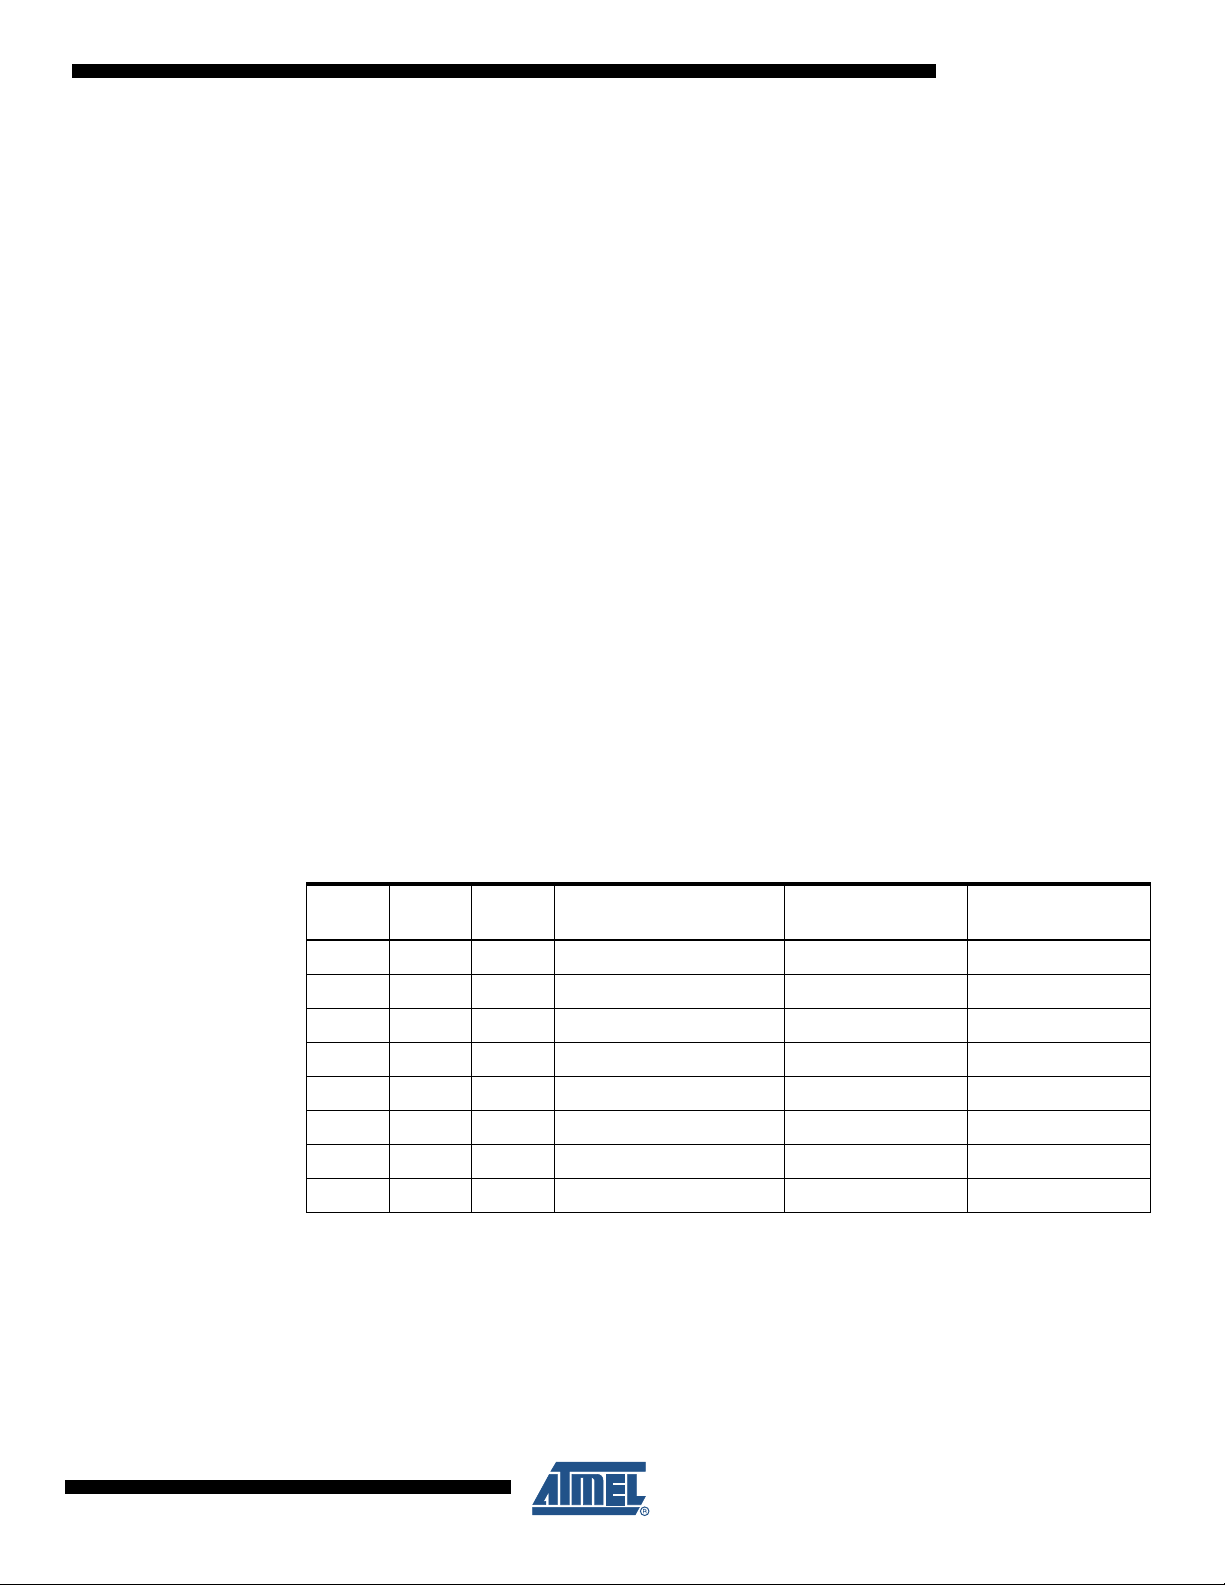
ATmega64A
• Bits 7:5 – Res: Reserved Bits
These bits are reserved bits in the ATmega64A and will always read as zero.
• Bit 4 – WDCE: Watchdog Change Enable
This bit must be set when the WDE bit is written to logic zero. Otherwise, the Watchdog will not
be disabled. Once written to one, hardware will clear this bit after four clock cycles. Refer to the
description of the WDE bit for a Watchdog disable procedure. In Safety Level 1 and 2, this bit
must also be set when changing the prescaler bits. See “Timed Sequences for Changing the
Configuration of the Watchdog Timer” on page 56.
• Bit 3 – WDE: Watchdog Enable
When the WDE is written to logic one, the Watchdog Timer is enabled, and if the WDE is written
to logic zero, the Watchdog Timer function is disabled. WDE can only be cleared if the WDCE bit
has logic level one. To disable an enabled Watchdog Timer, the following procedure must be
followed:
1. In the same operation, write a logic one to WDCE and WDE. A logic one must be written
to WDE even though it is set to one before the disable operation starts.
2. Within the next four clock cycles, write a logic 0 to WDE. This disables the Watchdog.
In safety level 2, it is not possible to disable the Watchdog Timer, even with the algorithm
described above. See “Timed Sequences for Changing the Configuration of the Watchdog
Timer” on page 56.
• Bits 2:0 – WDP2, WDP1, WDP0: Watchdog Timer Prescaler 2, 1, and 0
The WDP2, WDP1, and WDP0 bits determine the Watchdog Timer prescaling when the Watchdog Timer is enabled. The different prescaling values and their corresponding Timeout Periods
are shown in Table 10-2.
Table 10-2. Watchdog Timer Prescale Select
Number of WDT
WDP2 WDP1 WDP0
0 0 0 16K (16,384) 17.1 ms 16.3 ms
0 0 1 32K (32,768) 34.3 ms 32.5 ms
0 1 0 64K (65,536) 68.5 ms 65 ms
0 1 1 128K (131,072) 0.14 s 0.13 s
1 0 0 256K (262,144) 0.27 s 0.26 s
1 0 1 512K (524,288) 0.55 s 0.52 s
1 1 0 1,024K (1,048,576) 1.1 s 1.0 s
1 1 1 2,048K (2,097,152) 2.2 s 2.1 s
Oscillator Cycles
Typical Time-out
at VCC = 3.0V
Typical Time-out
at VCC = 5.0V
The following code examples show one assembly and one C function for turning off the WDT.
The examples assume that interrupts are controlled (e.g., by disabling interrupts globally) so that
no interrupts will occur during execution of these functions.
8160C–AVR–07/09
58
Page 59

Assembly Code Example
WDT_off:
; reset WDT
wdr
in r16, WDTCR
ldi r16, (1<<WDCE)|(1<<WDE)
; Write logical one to WDCE and WDE
ori r16, (1<<WDCE)|(1<<WDE)
out WDTCR, r16
; Turn off WDT
ldi r16, (0<<WDE)
out WDTCR, r16
ret
C Code Example
void WDT_off(void)
{
/* Reset WDT*/
_WDRC();
/* Write logical one to WDCE and WDE */
WDTCR |= (1<<WDCE) | (1<<WDE);
/* Turn off WDT */
WDTCR = 0x00;
}
ATmega64A
8160C–AVR–07/09
59
Page 60
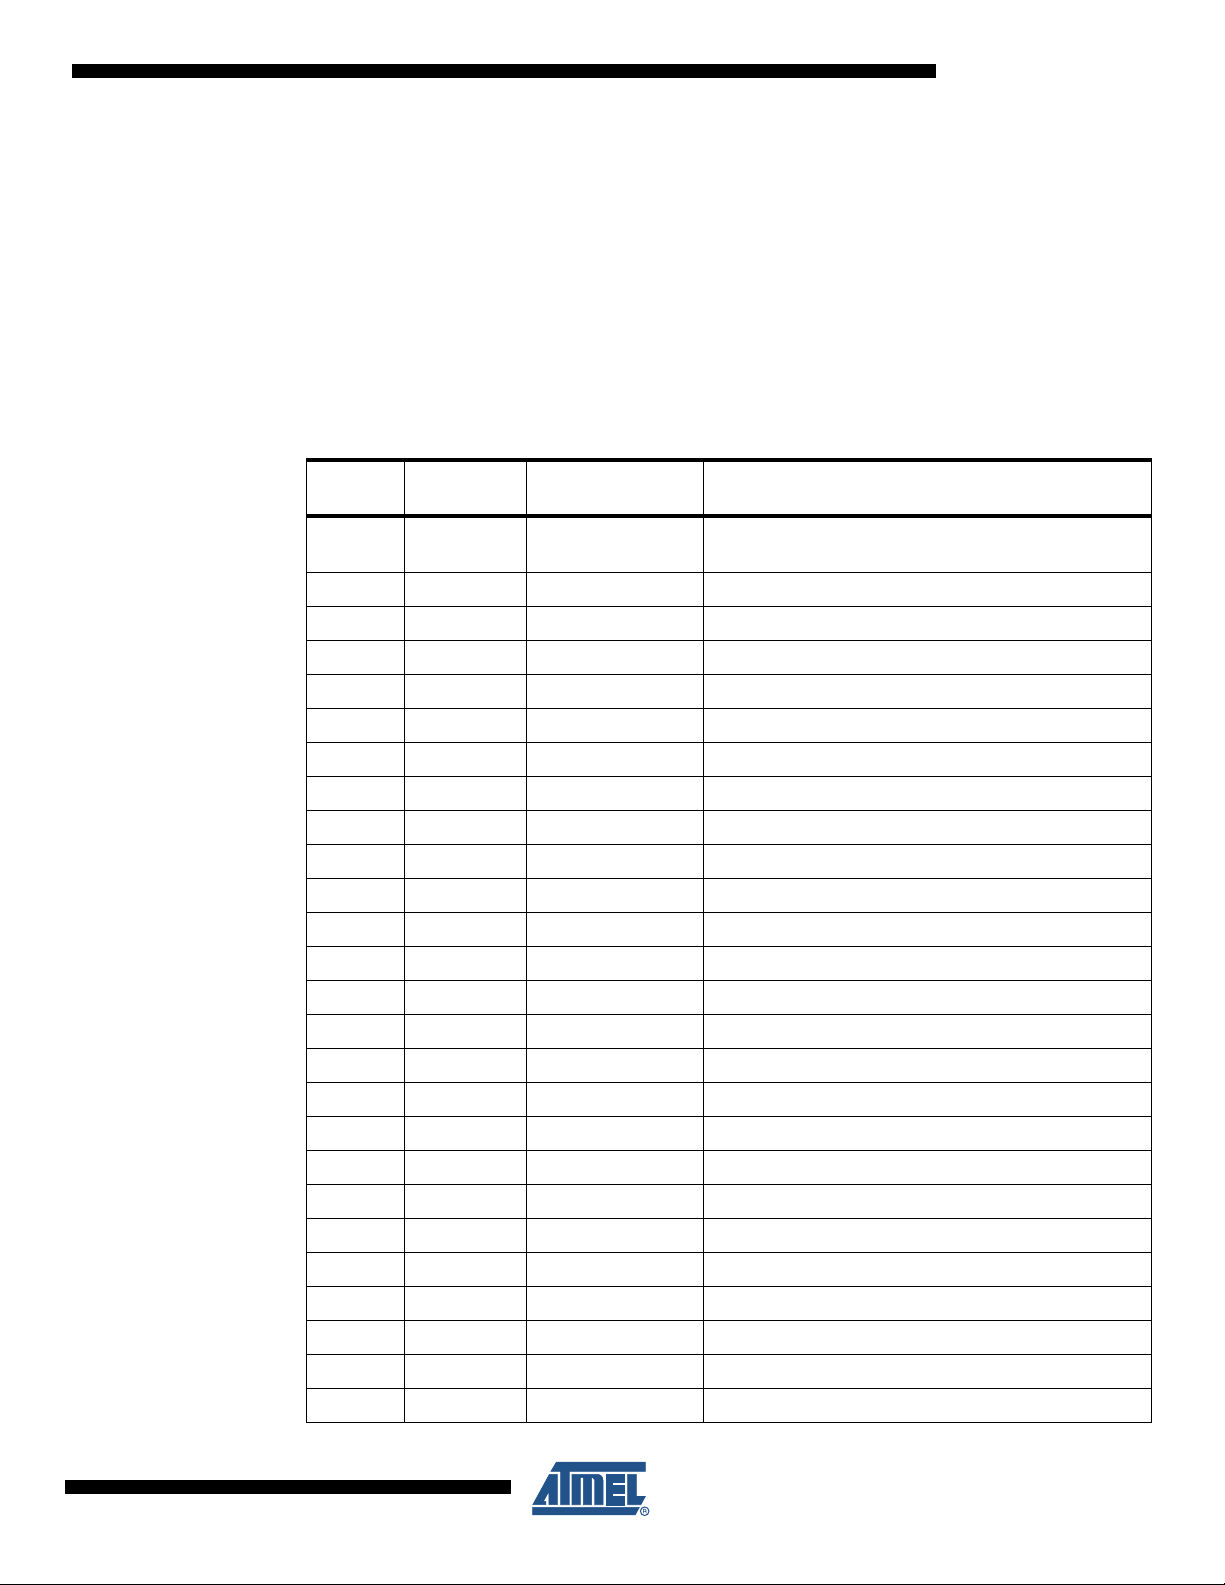
11. Interrupts
11.1 Overview
This section describes the specifics of the interrupt handling as performed in ATmega64A. For a
general explanation of the AVR interrupt handling, refer to “Reset and Interrupt Handling” on
page 14.
11.2 Interrupt Vectors in ATmega64A
Table 11-1. Reset and Interrupt Vectors
ATmega64A
Vector
No.
1 0x0000
2 0x0002 INT0 External Interrupt Request 0
3 0x0004 INT1 External Interrupt Request 1
4 0x0006 INT2 External Interrupt Request 2
5 0x0008 INT3 External Interrupt Request 3
6 0x000A INT4 External Interrupt Request 4
7 0x000C INT5 External Interrupt Request 5
8 0x000E INT6 External Interrupt Request 6
9 0x0010 INT7 External Interrupt Request 7
10 0x0012 TIMER2 COMP Timer/Counter2 Compare Match
11 0x0014 TIMER2 OVF Timer/Counter2 Overflow
12 0x0016 TIMER1 CAPT Timer/Counter1 Capture Event
13 0x0018 TIMER1 COMPA Timer/Counter1 Compare Match A
14 0x001A TIMER1 COMPB Timer/Counter1 Compare Match B
15 0x001C TIMER1 OVF Timer/Counter1 Overflow
16 0x001E TIMER0 COMP Timer/Counter0 Compare Match
Program
Address
(2)
Source Interrupt Definition
(1)
RESET External Pin, Power-on Reset, Brown-out Reset,
Watchdog Reset, and JTAG AVR Reset
8160C–AVR–07/09
17 0x0020 TIMER0 OVF Timer/Counter0 Overflow
18 0x0022 SPI, STC SPI Serial Transfer Complete
19 0x0024 USART0, RX USART0, Rx Complete
20 0x0026 USART0, UDRE USART0 Data Register Empty
21 0x0028 USART0, TX USART0, Tx Complete
22 0x002A ADC ADC Conversion Complete
23 0x002C EE READY EEPROM Ready
24 0x002E ANALOG COMP Analog Comparator
(3)
25 0x0030
26 0x0032
TIMER1 COMPC Timer/Countre1 Compare Match C
(3)
TIMER3 CAPT Timer/Counter3 Capture Event
60
Page 61
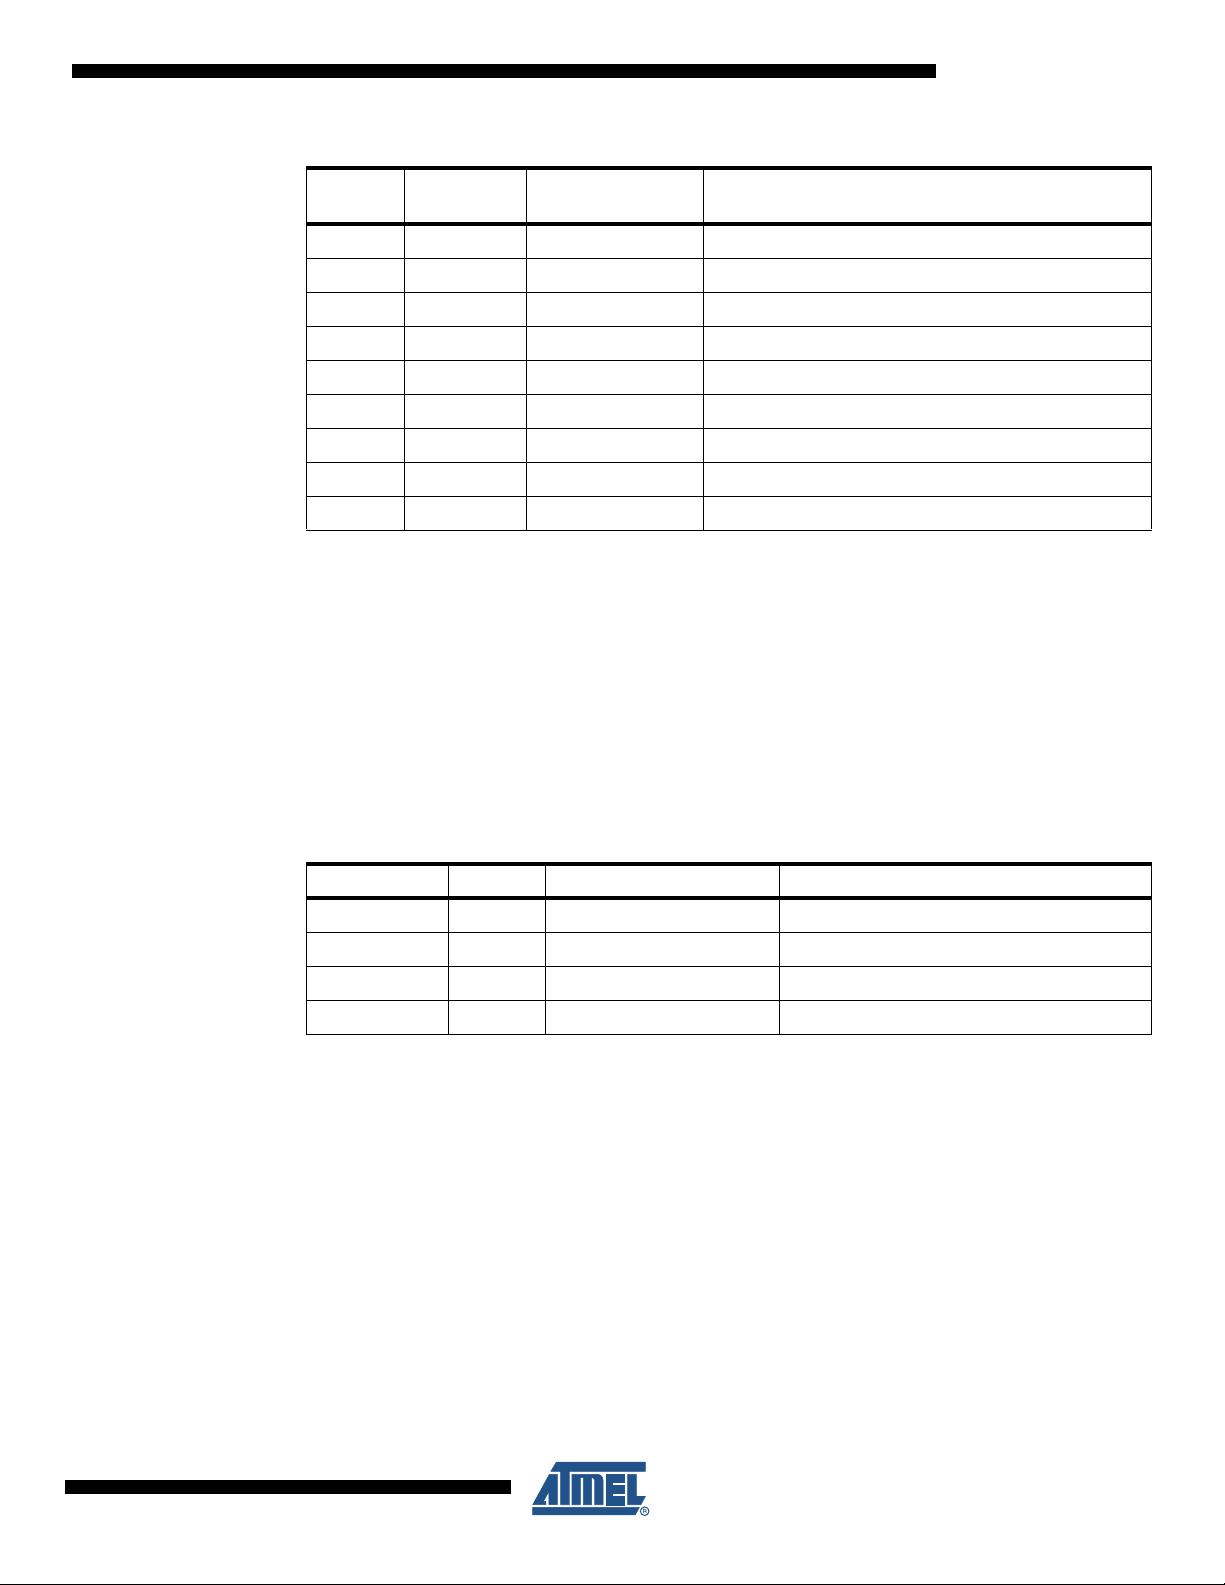
Table 11-1. Reset and Interrupt Vectors (Continued)
ATmega64A
Vector
No.
27 0x0034
28 0x0036
29 0x0038
30 0x003A
31 0x003C
32 0x003E
33 0x0040
34 0x0042
35 0x0044
Program
Address
(2)
Source Interrupt Definition
(3)
TIMER3 COMPA Timer/Counter3 Compare Match A
(3)
TIMER3 COMPB Timer/Counter3 Compare Match B
(3)
TIMER3 COMPC Timer/Counter3 Compare Match C
(3)
TIMER3 OVF Timer/Counter3 Overflow
(3)
USART1, RX USART1, Rx Complete
(3)
USART1, UDRE USART1 Data Register Empty
(3)
USART1, TX USART1, Tx Complete
(3)
TWI Two-wire Serial Interface
(3)
SPM READY Store Program Memory Ready
Notes: 1. When the BOOTRST Fuse is programmed, the device will jump to the Boot Loader address at
reset, see “Boot Loader Support – Read-While-Write Self-programming” on page 281.
2. When the IVSEL bit in MCUCR is set, Interrupt Vectors will be moved to the start of the Boot
Flash section. The address of each Interrupt Vector will then be address in this table added to
the start address of the Boot Flash section.
3. The Interrupts on address 0x0030 - 0x0044 do not exist in ATmega103 compatibility mode.
Table 11-2 shows Reset and Interrupt Vectors placement for the various combinations of
BOOTRST and IVSEL settings. If the program never enables an interrupt source, the Interrupt
Vectors are not used, and regular program code can be placed at these locations. This is also
the case if the Reset Vector is in the Application section while the Interrupt Vectors are in the
Boot section or vice versa.
Table 11-2. Reset and Interrupt Vectors Placement
(1)
BOOTRST IVSEL Reset Address Interrupt Vectors Start Address
1 0 0x0000 0x0002
1 1 0x0000 Boot Reset Address + 0x0002
0 0 Boot Reset Address 0x0002
0 1 Boot Reset Address Boot Reset Address + 0x0002
Note: 1. The Boot Reset Address is shown in Table 26-6 on page 292. For the BOOTRST Fuse “1”
means unprogrammed while “0” means programmed.
The most typical and general program setup for the Reset and Interrupt Vector Addresses in
ATmega64A is:
Address Labels Code Comments
0x0000 jmp RESET ; Reset Handler
0x0002 jmp EXT_INT0 ; IRQ0 Handler
0x0004 jmp EXT_INT1 ; IRQ1 Handler
0x0006 jmp EXT_INT2 ; IRQ2 Handler
0x0008 jmp EXT_INT3 ; IRQ3 Handler
0x000A jmp EXT_INT4 ; IRQ4 Handler
0x000C jmp EXT_INT5 ; IRQ5 Handler
0x000E jmp EXT_INT6 ; IRQ6 Handler
0x0010 jmp EXT_INT7 ; IRQ7 Handler
8160C–AVR–07/09
61
Page 62
ATmega64A
0x0012 jmp TIM2_COMP ; Timer2 Compare Handler
0x0014 jmp TIM2_OVF ; Timer2 Overflow Handler
0x0016 jmp TIM1_CAPT ; Timer1 Capture Handler
0x0018 jmp TIM1_COMPA ; Timer1 CompareA Handler
0x001A jmp TIM1_COMPB ; Timer1 CompareB Handler
0x001C jmp TIM1_OVF ; Timer1 Overflow Handler
0x001E jmp TIM0_COMP ; Timer0 Compare Handler
0x0020 jmp TIM0_OVF ; Timer0 Overflow Handler
0x0022 jmp SPI_STC ; SPI Transfer Complete Handler
0x0024 jmp USART0_RXC ; USART0 RX Complete Handler
0x0026 jmp USART0_DRE ; USART0,UDR Empty Handler
0x0028 jmp USART0_TXC ; USART0 TX Complete Handler
0x002A jmp ADC ; ADC Conversion Complete Handler
0x002C jmp EE_RDY ; EEPROM Ready Handler
0x002E jmp ANA_COMP ; Analog Comparator Handler
0x0030 jmp TIM1_COMPC ; Timer1 CompareC Handler
0x0032 jmp TIM3_CAPT ; Timer3 Capture Handler
0x0034 jmp TIM3_COMPA ; Timer3 CompareA Handler
0x0036 jmp TIM3_COMPB ; Timer3 CompareB Handler
0x0038 jmp TIM3_COMPC ; Timer3 CompareC Handler
0x003A jmp TIM3_OVF ; Timer3 Overflow Handler
0x003C jmp USART1_RXC ; USART1 RX Complete Handler
0x003E jmp USART1_DRE ; USART1,UDR Empty Handler
0x0040 jmp USART1_TXC ; USART1 TX Complete Handler
0x0042 jmp TWI ; Two-wire Serial Interface Handler
0x0044 jmp SPM_RDY ; SPM Ready Handler
;
0x0046 RESET: ldi r16, high(RAMEND); Main program start
0x0047 out SPH,r16 ; Set Stack Pointer to top of RAM
0x0048 ldi r16, low(RAMEND)
0x0049 out SPL,r16
0x004A sei ; Enable interrupts
0x004B <instr> xxx
:. :. :. :.
When the BOOTRST Fuse is unprogrammed, the Boot section size set to 8K bytes and the
IVSEL bit in the MCUCR Register is set before any interrupts are enabled, the most typical and
general program setup for the Reset and Interrupt Vector Addresses is:
8160C–AVR–07/09
Address Labels Code Comments
0x0000 RESET: ldi r16,high(RAMEND); Main program start
0x0001 out SPH,r16 ; Set Stack Pointer to top of RAM
0x0002 ldi r16,low(RAMEND)
0x0003 out SPL,r16
0x0004 sei ; Enable interrupts
0x0005 <instr> xxx
;
.org 0x7002
0x7002 jmp EXT_INT0 ; IRQ0 Handler
0x7004 jmp EXT_INT1 ; IRQ1 Handler
:. :. :. ;
0x7044 jmp SPM_RDY ; Store Program Memory Ready Handler
62
Page 63
ATmega64A
When the BOOTRST Fuse is programmed and the Boot section size set to 8K bytes, the most
typical and general program setup for the Reset and Interrupt Vector Addresses is:
Address Labels Code Comments
.org 0x0002
0x0002 jmp EXT_INT0 ; IRQ0 Handler
0x0004 jmp EXT_INT1 ; IRQ1 Handler
:. :. :. ;
0x0044 jmp SPM_RDY ; Store Program Memory Ready Handler
;
.org 0x7000
0x7000 RESET: ldi r16,high(RAMEND); Main program start
0x7001 out SPH,r16 ; Set Stack Pointer to top of RAM
0x7002 ldi r16,low(RAMEND)
0x7003 out SPL,r16
0x7004 sei ; Enable interrupts
0x7005 <instr> xxx
When the BOOTRST Fuse is programmed, the Boot section size set to 8K bytes and the IVSEL
bit in the MCUCR Register is set before any interrupts are enabled, the most typical and general
program setup for the Reset and Interrupt Vector Addresses is:
Address Labels Code Comments
;
.org 0x7000
0x7000 jmp RESET ; Reset handler
0x7002 jmp EXT_INT0 ; IRQ0 Handler
0x7004 jmp EXT_INT1 ; IRQ1 Handler
:. :. :. ;
0x7044 jmp SPM_RDY ; Store Program Memory Ready Handler
0x7046 RESET: ldi r16,high(RAMEND); Main program start
0x7047 out SPH,r16 ; Set Stack Pointer to top of RAM
0x7048 ldi r16,low(RAMEND)
0x7049 out SPL,r16
0x704A sei ; Enable interrupts
0x704B <instr> xxx
11.2.1 Moving Interrupts Between Application and Boot Space
The General Interrupt Control Register controls the placement of the Interrupt Vector table.
8160C–AVR–07/09
63
Page 64
11.3 Register Description
11.3.1 MCUCR – MCU Control Register
Bit 76543210
0x35 (0x55)
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value00000000
• Bit 1 – IVSEL: Interrupt Vector Select
When the IVSEL bit is cleared (zero), the Interrupt Vectors are placed at the start of the Flash
memory. When this bit is set (one), the Interrupt Vectors are moved to the beginning of the Boot
Loader section of the Flash. The actual address of the start of the Boot Flash section is determined by the BOOTSZ Fuses. Refer to the section “Boot Loader Support – Read-While-Write
Self-programming” on page 281 for details. To avoid unintentional changes of Interrupt Vector
tables, a special write procedure must be followed to change the IVSEL bit:
1. Write the Interrupt Vector Change Enable (IVCE) bit to one.
2. Within four cycles, write the desired value to IVSEL while writing a zero to IVCE.
Interrupts will automatically be disabled while this sequence is executed. Interrupts are disabled
in the cycle IVCE is set, and they remain disabled until after the instruction following the write to
IVSEL. If IVSEL is not written, interrupts remain disabled for four cycles. The I-bit in the Status
Register is unaffected by the automatic disabling.
Note: If Interrupt Vectors are placed in the Boot Loader section and Boot Lock bit BLB02 is programmed,
SRE SRW10 SE SM1 SM0 SM2 IVSEL IVCE MCUCR
interrupts are disabled while executing from the Application section. If Interrupt Vectors are placed
in the Application section and Boot Lock bit BLB12 is programed, interrupts are disabled while
executing from the Boot Loader section. Refer to the section “Boot Loader Support – Read-While-
Write Self-programming” on page 281 for details on Boot Lock bits.
ATmega64A
• Bit 0 – IVCE: Interrupt Vector Change Enable
The IVCE bit must be written to logic one to enable change of the IVSEL bit. IVCE is cleared by
hardware four cycles after it is written or when IVSEL is written. Setting the IVCE bit will disable
interrupts, as explained in the IVSEL description above. See code examples below.
Assembly Code Example
Move_interrupts:
; Enable change of Interrupt Vectors
ldi r16, (1<<IVCE)
out MCUCR, r16
; Move interrupts to boot Flash section
ldi r16, (1<<IVSEL)
out MCUCR, r16
ret
C Code Example
void Move_interrupts(void)
{
/* Enable change of Interrupt Vectors */
MCUCR = (1<<IVCE);
/* Move interrupts to boot Flash section */
MCUCR = (1<<IVSEL);
}
8160C–AVR–07/09
64
Page 65
12. External Interrupts
The External Interrupts are triggered by the INT7:0 pins. Observe that, if enabled, the interrupts
will trigger even if the INT7:0 pins are configured as outputs. This feature provides a way of generating a software interrupt. The external interrupts can be triggered by a falling or rising edge or
a low level. This is set up as indicated in the specification for the External Interrupt Control Registers – EICRA (INT3:0) and EICRB (INT7:4). When the External Interrupt is enabled and is
configured as level triggered, the interrupt will trigger as long as the pin is held low. Note that
recognition of falling or rising edge interrupts on INT7:4 requires the presence of an I/O clock,
described in “Clock Systems and their Distribution” on page 37. Low level interrupts and the
edge interrupt on INT3:0 are detected asynchronously. This implies that these interrupts can be
used for waking the part also from sleep modes other than Idle mode. The I/O clock is halted in
all sleep modes except Idle mode.
Note that if a level triggered interrupt is used for wake-up from Power-down mode, the changed
level must be held for some time to wake up the MCU. This makes the MCU less sensitive to
noise. The changed level is sampled twice by the Watchdog Oscillator clock. The period of the
Watchdog Oscillator is 1 µs (nominal) at 5.0V and 25⋅C. The frequency of the Watchdog Oscillator is voltage dependent as shown in the “Electrical Characteristics” on page 327. The MCU will
wake up if the input has the required level during this sampling or if it is held until the end of the
start-up time. The start-up time is defined by the SUT Fuses as described in “Clock Systems and
their Distribution” on page 37. If the level is sampled twice by the Watchdog Oscillator clock but
disappears before the end of the start-up time, the MCU will still wake up, but no interrupt will be
generated. The required level must be held long enough for the MCU to complete the wake up to
trigger the level interrupt.
ATmega64A
12.1 Register Description
12.1.1 EICRA – External Interrupt Control Register A
Bit 76543210
(0x6A) ISC31 ISC30 ISC21 ISC20 ISC11 ISC10 ISC01 ISC00 EICRA
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value00000000
This Register can not be reached in ATmega103 compatibility mode, but the Initial Value defines
INT3:0 as low level interrupts, as in ATmega103.
• Bits 7:0 – ISC31, ISC30 - ISC00, ISC00: External Interrupt 3 - 0 Sense Control Bits
The External Interrupts 3 - 0 are activated by the external pins INT3:0 if the SREG I-flag and the
corresponding interrupt mask in the EIMSK is set. The level and edges on the external pins that
activate the interrupts are defined in Table 12-1 on page 66. Edges on INT3:INT0 are registered
asynchronously. Pulses on INT3:0 pins wider than the minimum pulse width given in Table 12-2
on page 66 will generate an interrupt. Shorter pulses are not guaranteed to generate an inter-
rupt. If low level interrupt is selected, the low level must be held until the completion of the
currently executing instruction to generate an interrupt. If enabled, a level triggered interrupt will
generate an interrupt request as long as the pin is held low. When changing the ISCn bit, an
interrupt can occur. Therefore, it is recommended to first disable INTn by clearing its Interrupt
Enable bit in the EIMSK Register. Then, the ISCn bit can be changed. Finally, the INTn interrupt
flag should be cleared by writing a logical one to its Interrupt Flag bit (INTFn) in the EIFR Register before the interrupt is re-enabled.
8160C–AVR–07/09
65
Page 66
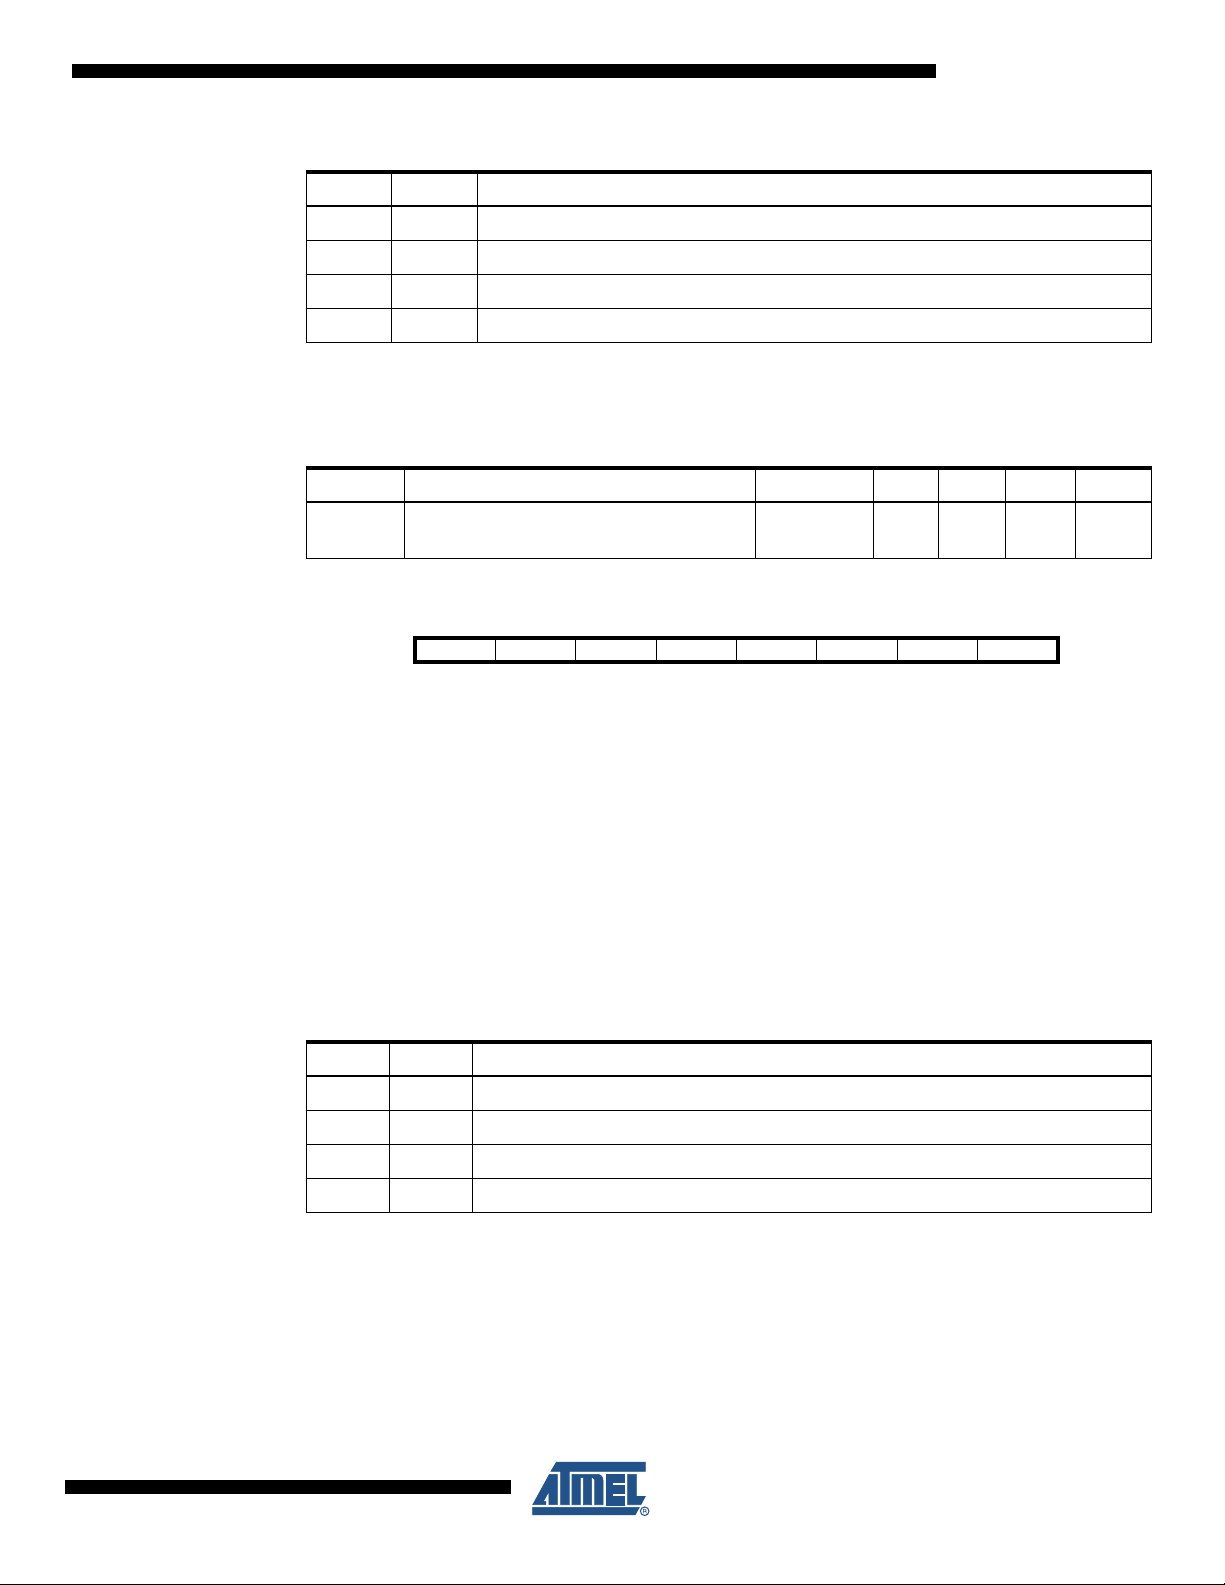
ATmega64A
Table 12-1. Interrupt Sense Control
ISCn1 ISCn0 Description
0 0 The low level of INTn generates an interrupt request.
01Reserved
1 0 The falling edge of INTn generates asynchronously an interrupt request.
1 1 The rising edge of INTn generates asynchronously an interrupt request.
Note: 1. n = 3, 2, 1or 0.
When changing the ISCn1/ISCn0 bits, the interrupt must be disabled by clearing its Interrupt
Enable bit in the EIMSK Register. Otherwise an interrupt can occur when the bits are changed.
Table 12-2. Asynchronous External Interrupt Characteristics
Symbol Parameter Condition Min Typ Max Units
t
INT
Minimum pulse width for asynchronous
External Interrupt
12.1.2 EICRB – External Interrupt Control Register B
Bit 76543210
0x3A (0x5A) ISC71 ISC70 ISC61 ISC60 ISC51 ISC50 ISC41 ISC40 EICRB
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value00000000
(1)
50 ns
• Bits 7:0 – ISC71, ISC70 - ISC41, ISC40: External Interrupt 7 - 4 Sense Control Bits
The External Interrupts 7 - 4 are activated by the external pins INT7:4 if the SREG I-flag and the
corresponding interrupt mask in the EIMSK is set. The level and edges on the external pins that
activate the interrupts are defined in Table 12-3. The value on the INT7:4 pins are sampled
before detecting edges. If edge or toggle interrupt is selected, pulses that last longer than one
clock period will generate an interrupt. Shorter pulses are not guaranteed to generate an interrupt. Observe that CPU clock frequency can be lower than the XTAL frequency if the XTAL
divider is enabled. If low level interrupt is selected, the low level must be held until the completion of the currently executing instruction to generate an interrupt. If enabled, a level triggered
interrupt will generate an interrupt request as long as the pin is held low.
Table 12-3. Interrupt Sense Control
ISCn1 ISCn0 Description
0 0 The low level of INTn generates an interrupt request.
0 1 Any logical change on INTn generates an interrupt request
1 0 The falling edge between two samples of INTn generates an interrupt request.
1 1 The rising edge between two samples of INTn generates an interrupt request.
Note: 1. n = 7, 6, 5 or 4.
When changing the ISCn1/ISCn0 bits, the interrupt must be disabled by clearing its Interrupt
Enable bit in the EIMSK Register. Otherwise an interrupt can occur when the bits are changed.
(1)
8160C–AVR–07/09
66
Page 67
12.1.3 EIMSK – External Interrupt Mask Register
Bit 76543210
0x39 (0x59) INT7 INT6 INT5 INT4 INT3 INT2 INT1 INT0 EIMSK
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value00000000
• Bits 7:4 – INT7 - INT0: External Interrupt Request 7 - 0 Enable
When an INT7 - INT4 bit is written to one and the I-bit in the Status Register (SREG) is set (one),
the corresponding external pin interrupt is enabled. The Interrupt Sense Control bits in the External Interrupt Control Registers – EICRA and EICRB defines whether the External Interrupt is
activated on rising or falling edge or level sensed. Activity on any of these pins will trigger an
interrupt request even if the pin is enabled as an output. This provides a way of generating a
software interrupt.
12.1.4 EIFR – External Interrupt Flag Register
Bit 76543210
0x38 (0x58) INTF7 INTF6 INTF5 INTF4 INTF3 INTF2 INTF1 INTF0 EIFR
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value00000000
ATmega64A
• Bits 7:0 – INTF7 - INTF0: External Interrupt Flags 7 - 0
When an edge or logic change on the INT7:0 pin triggers an interrupt request, INTF7:0 becomes
set (one). If the I-bit in SREG and the corresponding Interrupt Enable bit, INT7:0 in EIMSK, are
set (one), the MCU will jump to the Interrupt Vector. The flag is cleared when the interrupt routine is executed. Alternatively, the flag can be cleared by writing a logical one to it. These flags
are always cleared when INT7:0 are configured as level interrupt. Note that when entering sleep
mode with the INT3:0 interrupts disabled, the input buffers on these pins will be disabled. This
may cause a logic change in internal signals which will set the INTF3:0 flags. See “Digital Input
Enable and Sleep Modes” on page 72 for more information.
8160C–AVR–07/09
67
Page 68
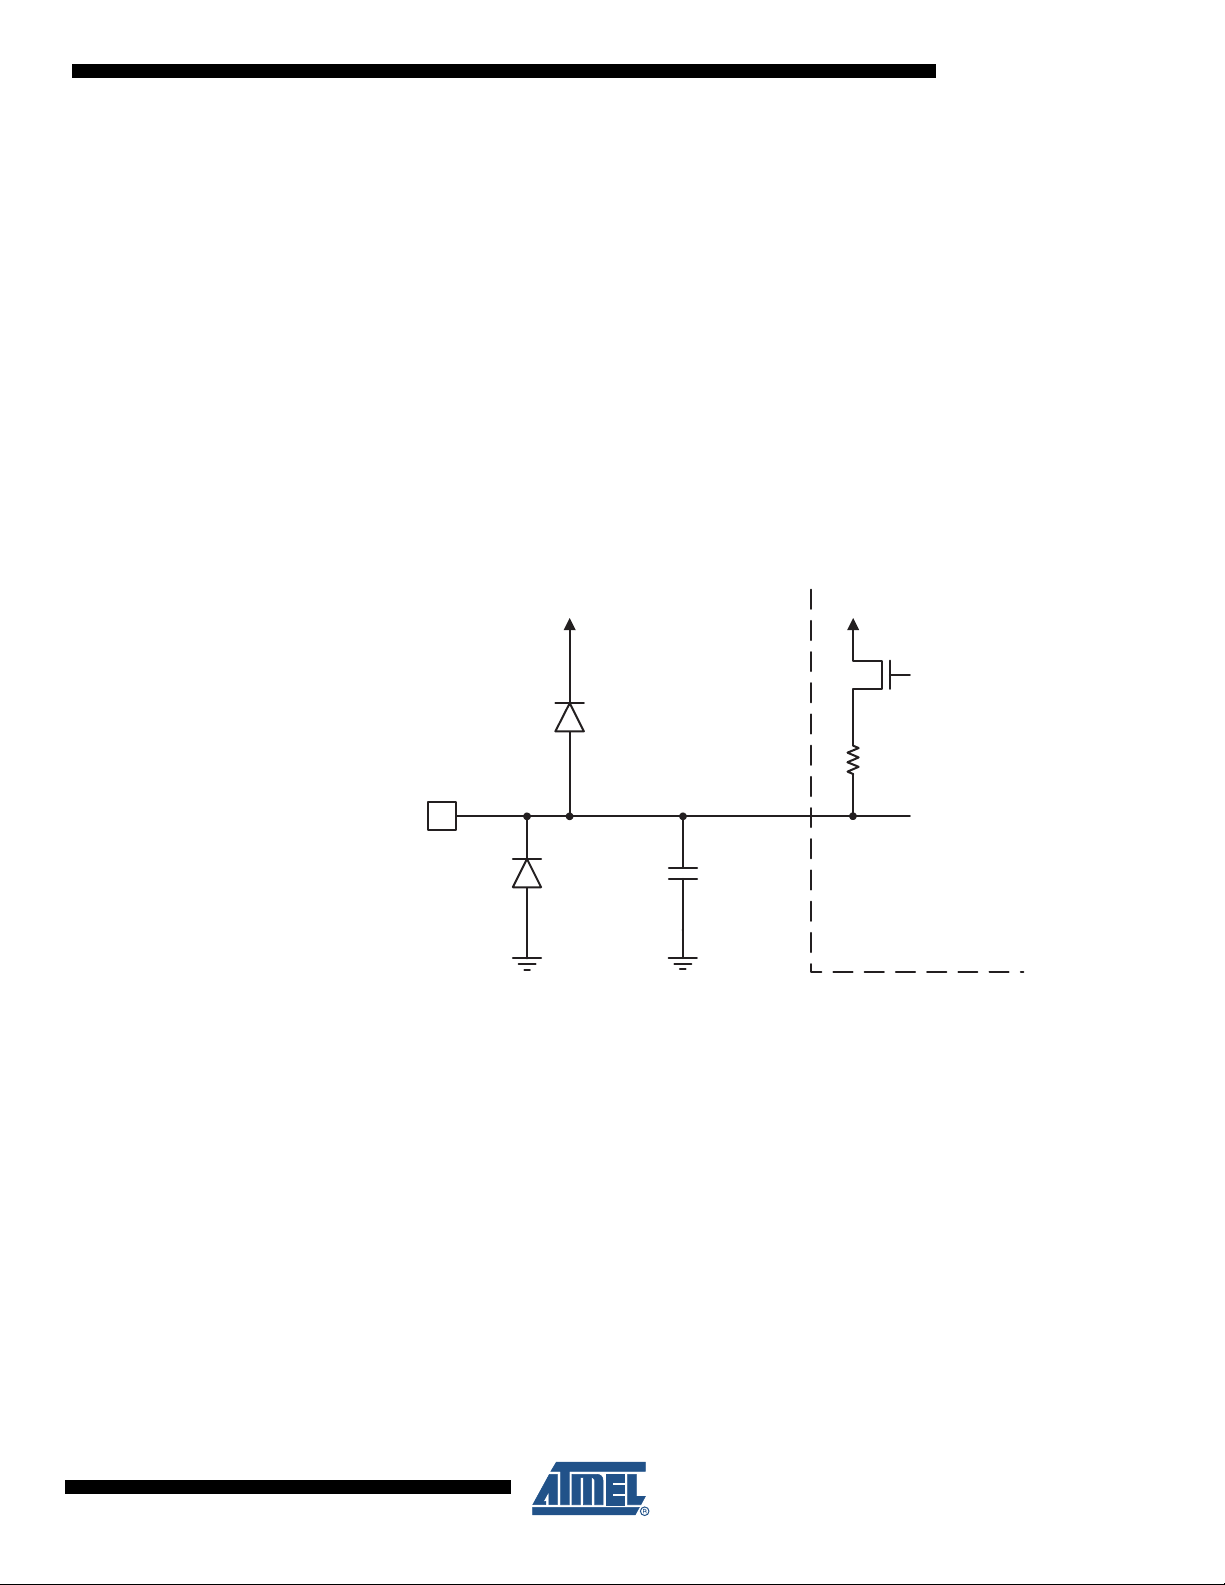
13. I/O Ports
C
pin
Logic
R
pu
See Figure
"General Digital I/O" for
Details
Pxn
13.1 Overview
ATmega64A
All AVR ports have true Read-Modify-Write functionality when used as general digital I/O ports.
This means that the direction of one port pin can be changed without unintentionally changing
the direction of any other pin with the SBI and CBI instructions. The same applies when changing drive value (if configured as output) or enabling/disabling of pull-up resistors (if configured as
input). Each output buffer has symmetrical drive characteristics with both high sink and source
capability. The pin driver is strong enough to drive LED displays directly. All port pins have individually selectable pull-up resistors with a supply voltage invariant resistance. All I/O pins have
protection diodes to both V
acteristics” on page 327 for a complete list of parameters.
Figure 13-1. I/O Pin Equivalent Schematic
and Ground as indicated in Figure 13-1. Refer to “Electrical Char-
CC
8160C–AVR–07/09
All registers and bit references in this section are written in general form. A lower case “x” represents the numbering letter for the port, and a lower case “n” represents the bit number. However,
when using the register or bit defines in a program, the precise form must be used (i.e., PORTB3
for bit no. 3 in Port B, here documented generally as PORTxn). The physical I/O Registers and
bit locations are listed in “Register Description” on page 88.
Three I/O memory address locations are allocated for each port, one each for the Data Register
– PORTx, Data Direction Register – DDRx, and the Port Input Pins – PINx. The Port Input Pins
I/O location is read only, while the Data Register and the Data Direction Register are read/write.
In addition, the Pull-up Disable – PUD bit in SFIOR disables the pull-up function for all pins in all
ports when set.
Using the I/O port as general digital I/O is described in “Ports as General Digital I/O” on page 69.
Most port pins are multiplexed with alternate functions for the peripheral features on the device.
How each alternate function interferes with the port pin is described in “Alternate Port Functions”
on page 73. Refer to the individual module sections for a full description of the alternate
functions.
68
Page 69
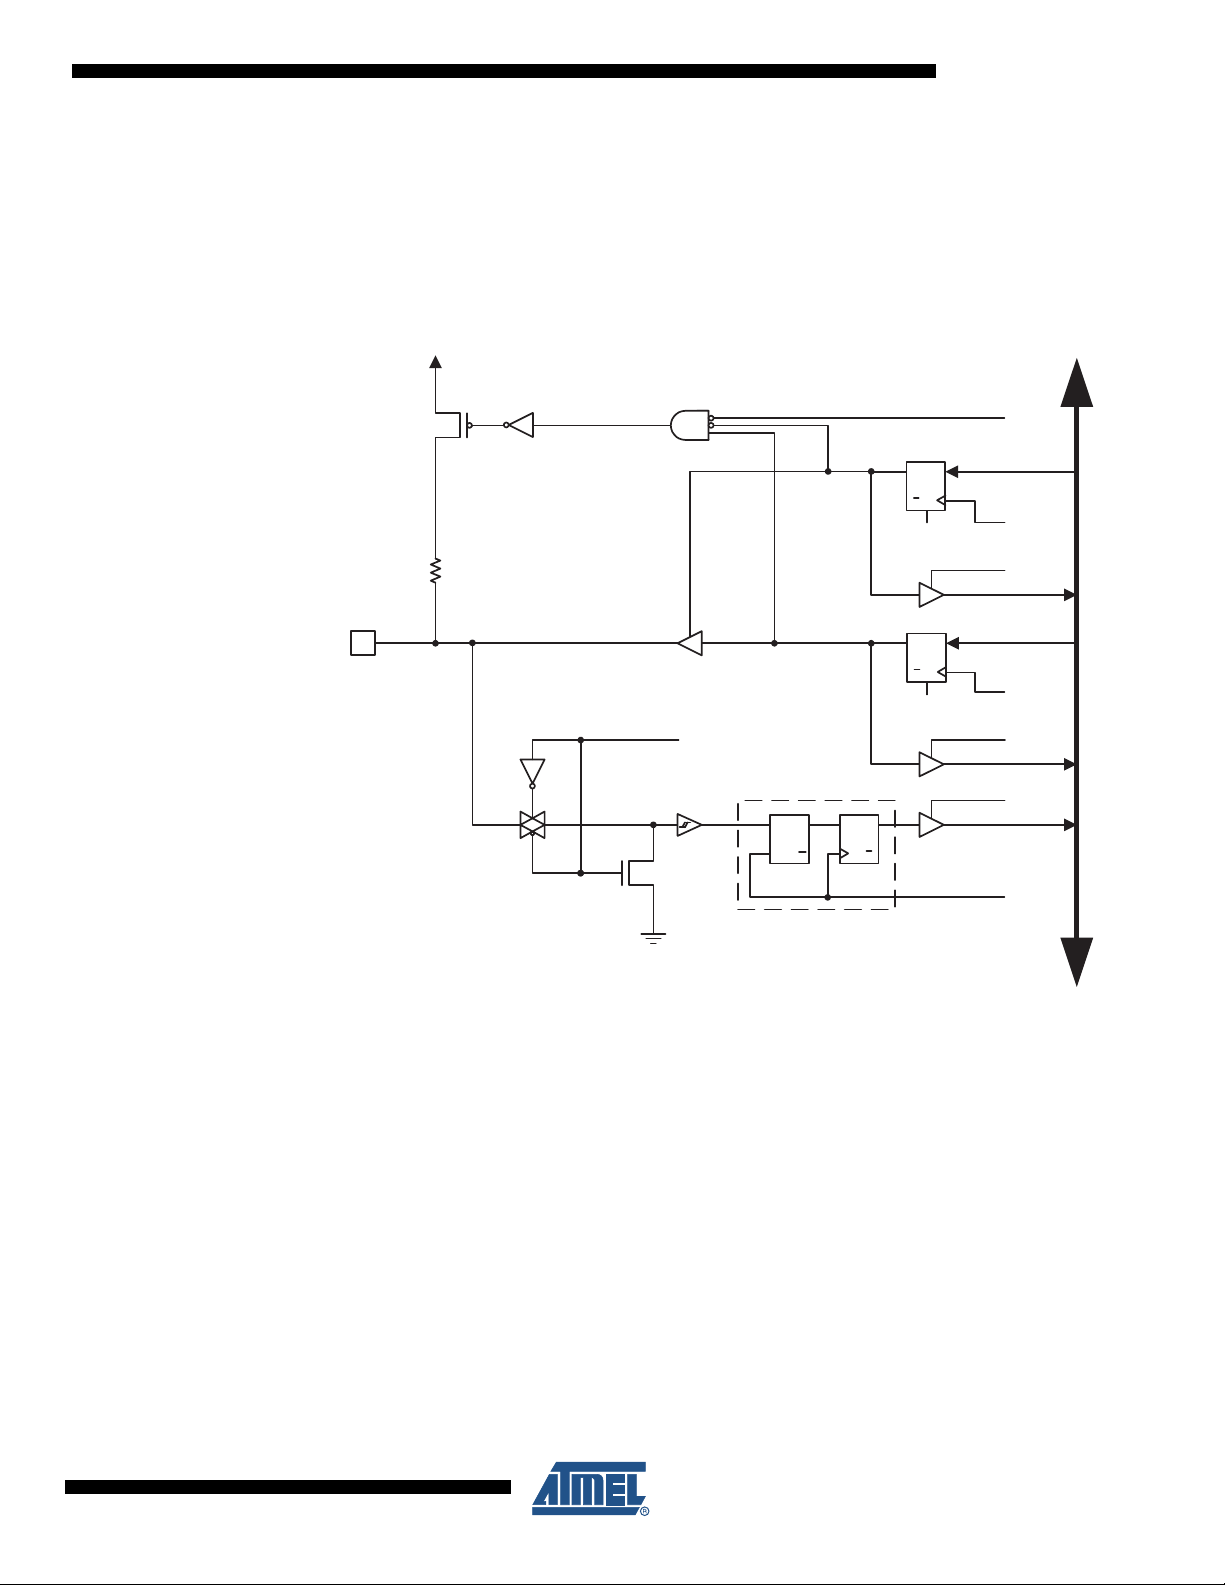
Note that enabling the alternate function of some of the port pins does not affect the use of the
clk
RPx
RRx
WPx
RDx
WDx
PUD
SYNCHRONIZER
WDx: WRITE DDRx
WPx: WRITE PORTx
RRx: READ PORTx REGISTER
RPx: READ PORTx PIN
PUD: PULLUP DISABLE
clk
I/O
: I/O CLOCK
RDx: READ DDRx
DLQ
Q
RESET
RESET
Q
Q
D
Q
Q
D
CLR
PORTxn
Q
Q
D
CLR
DDxn
PINxn
DATA B US
SLEEP
SLEEP: SLEEP CONTROL
Pxn
I/O
other pins in the port as general digital I/O.
13.2 Ports as General Digital I/O
The ports are bi-directional I/O ports with optional internal pull-ups. Figure 13-2 shows a functional description of one I/O-port pin, here generically called Pxn.
ATmega64A
Figure 13-2. General Digital I/O
(1)
Note: 1. WPx, WDx, RRx, RPx, and RDx are common to all pins within the same port. clk
13.2.1 Configuring the Pin
Each port pin consists of three register bits: DDxn, PORTxn, and PINxn. As shown in “Register
Description” on page 88, the DDxn bits are accessed at the DDRx I/O address, the PORTxn bits
at the PORTx I/O address, and the PINxn bits at the PINx I/O address.
The DDxn bit in the DDRx Register selects the direction of this pin. If DDxn is written logic one,
Pxn is configured as an output pin. If DDxn is written logic zero, Pxn is configured as an input
pin.
If PORTxn is written logic one when the pin is configured as an input pin, the pull-up resistor is
activated. To switch the pull-up resistor off, PORTxn has to be written logic zero or the pin has to
be configured as an output pin. The port pins are tri-stated when a reset condition becomes
active, even if no clocks are running.
8160C–AVR–07/09
and PUD are common to all ports.
, SLEEP,
I/O
69
Page 70
ATmega64A
If PORTxn is written logic one when the pin is configured as an output pin, the port pin is driven
high (one). If PORTxn is written logic zero when the pin is configured as an output pin, the port
pin is driven low (zero).
When switching between tri-state ({DDxn, PORTxn} = 0b00) and output high ({DDxn,
PORTxn } = 0b11), an intermediate state with either pull-up enabled ({DDxn, PORTxn} = 0b01)
or output low ({DDxn, PORTxn} = 0b10) must occur. Normally, the pull-up enabled state is fully
acceptable, as a high-impedant environment will not notice the difference between a strong high
driver and a pull-up. If this is not the case, the PUD bit in the SFIOR Register can be written to
one to disable all pull-ups in all ports.
Switching between input with pull-up and output low generates the same problem. The user
must use either the tri-state ({DDxn, PORTxn} = 0b00) or the output high state({DDxn,
PORTxn} = 0b11) as an intermediate step.
Table 13-1 summarizes the control signals for the pin value.
Table 13-1. Port Pin Configurations
PUD
DDxn PORTxn
0 0 X Input No Tri-state (Hi-Z)
(in SFIOR) I/O Pull-up Comment
0 1 0 Input Yes Pxn will source current if ext. pulled low.
0 1 1 Input No Tri-state (Hi-Z)
1 0 X Output No Output Low (Sink)
1 1 X Output No Output High (Source)
13.2.2 Reading the Pin Value
Independent of the setting of Data Direction bit DDxn, the port pin can be read through the
PINxn Register bit. As shown in Figure 13-2, the PINxn Register bit and the preceding latch constitute a synchronizer. This is needed to avoid metastability if the physical pin changes value
near the edge of the internal clock, but it also introduces a delay. Figure 13-3 shows a timing diagram of the synchronization when reading an externally applied pin value. The maximum and
minimum propagation delays are denoted t
pd,max
and t
respectively.
pd,min
8160C–AVR–07/09
70
Page 71
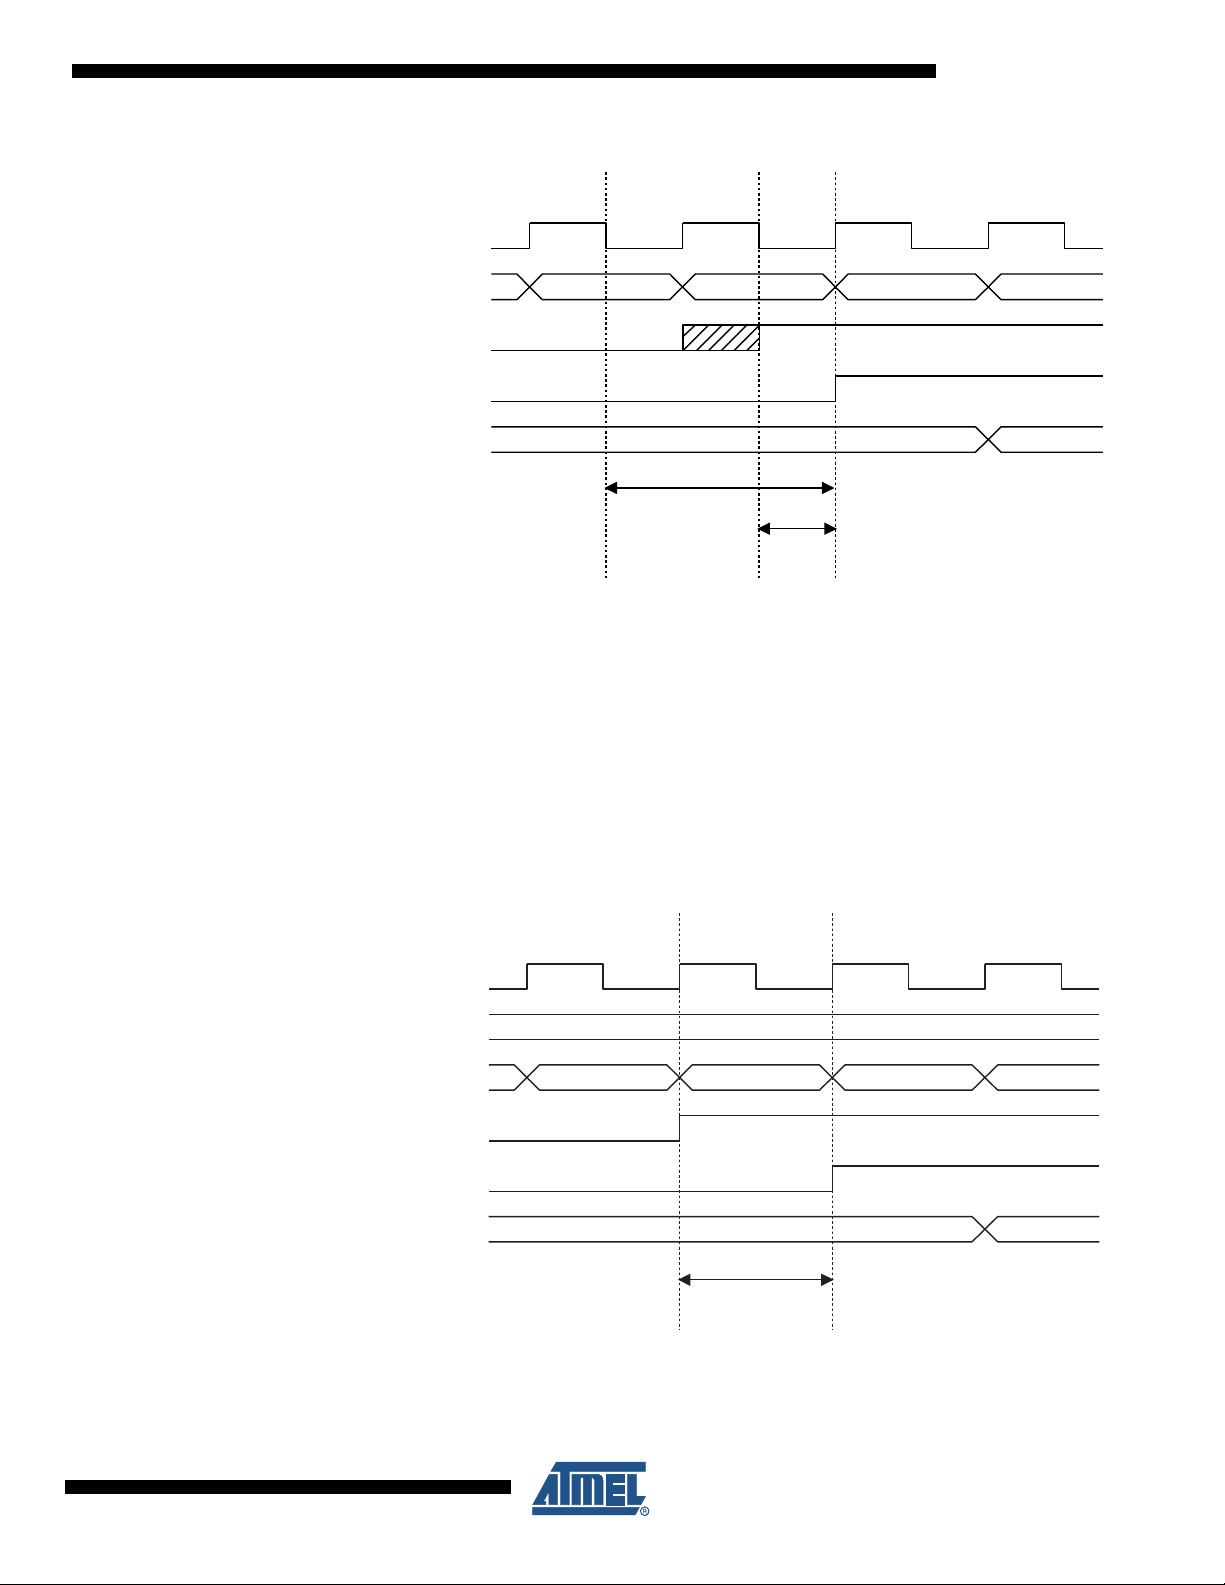
ATmega64A
SYSTEM CLK
INSTRUCTIONS
SYNC LATCH
PINxn
r17
in r17, PINx
0xFF
0x00
t
pd, max
XXXXXX
t
pd, min
nop in r17, PINx
0xFF
0x00
0xFF
t
pd
out PORTx, r16
SYSTEM CLK
r16
INSTRUCTIONS
SYNC LATCH
PINxn
r17
Figure 13-3. Synchronization when Reading an Externally Applied Pin Value
Consider the clock period starting shortly after the first falling edge of the system clock. The latch
is closed when the clock is low, and goes transparent when the clock is high, as indicated by the
shaded region of the “SYNC LATCH” signal. The signal value is latched when the system clock
goes low. It is clocked into the PINxn Register at the succeeding positive clock edge. As indicated by the two arrows t
between ½ and 1-½ system clock period depending upon the time of assertion.
pd,max
and t
, a single signal transition on the pin will be delayed
pd,min
8160C–AVR–07/09
When reading back a software assigned pin value, a nop instruction must be inserted as indi-
cated in Figure 13-4. The out instruction sets the “SYNC LATCH” signal at the positive edge of
the clock. In this case, the delay t
through the synchronizer is one system clock period.
pd
Figure 13-4. Synchronization when Reading a Software Assigned Pin Value
The following code example show how to set Port B pins 0 and 1 high, 2 and 3 low, and define
the port pins from 4 to 7 as input with pull-ups assigned to port pins 6 and 7. The resulting pin
71
Page 72
ATmega64A
values are read back again, but as previously discussed, a nop instruction is included to be able
to read back the value recently assigned to some of the pins.
Assembly Code Example
:.
; Define pull-ups and set outputs high
; Define directions for port pins
ldi r16,(1<<PB7)|(1<<PB6)|(1<<PB1)|(1<<PB0)
ldi r17,(1<<DDB3)|(1<<DDB2)|(1<<DDB1)|(1<<DDB0)
out PORTB,r16
out DDRB,r17
; Insert nop for synchronization
nop
; Read port pins
in r16,PINB
:.
(1)
C Code Example
unsigned char i;
:.
/* Define pull-ups and set outputs high */
/* Define directions for port pins */
PORTB = (1<<PB7)|(1<<PB6)|(1<<PB1)|(1<<PB0);
DDRB = (1<<DDB3)|(1<<DDB2)|(1<<DDB1)|(1<<DDB0);
/* Insert nop for synchronization*/
_NOP();
/* Read port pins */
i = PINB;
:.
Note: 1. For the assembly program, two temporary registers are used to minimize the time from pull-
ups are set on pins 0, 1, 6, and 7, until the direction bits are correctly set, defining bit 2 and 3
as low and redefining bits 0 and 1 as strong high drivers.
13.2.3 Digital Input Enable and Sleep Modes
As shown in Figure 13-2, the digital input signal can be clamped to ground at the input of the
Schmitt Trigger. The signal denoted SLEEP in the figure, is set by the MCU Sleep Controller in
Power-down mode, Power-save mode, Standby mode, and Extended Standby mode to avoid
high power consumption if some input signals are left floating, or have an analog signal level
close to V
CC
/2.
SLEEP is overridden for port pins enabled as External Interrupt pins. If the External Interrupt
request is not enabled, SLEEP is active also for these pins. SLEEP is also overridden by various
other alternate functions as described in “Alternate Port Functions” on page 73.
If a logic high level (“one”) is present on an asynchronous External Interrupt pin configured as
“Interrupt on Any Logic Change on Pin” while the External Interrupt is not enabled, the corresponding External Interrupt Flag will be set when resuming from the above mentioned sleep
modes, as the clamping in these sleep modes produces the requested logic change.
8160C–AVR–07/09
72
Page 73
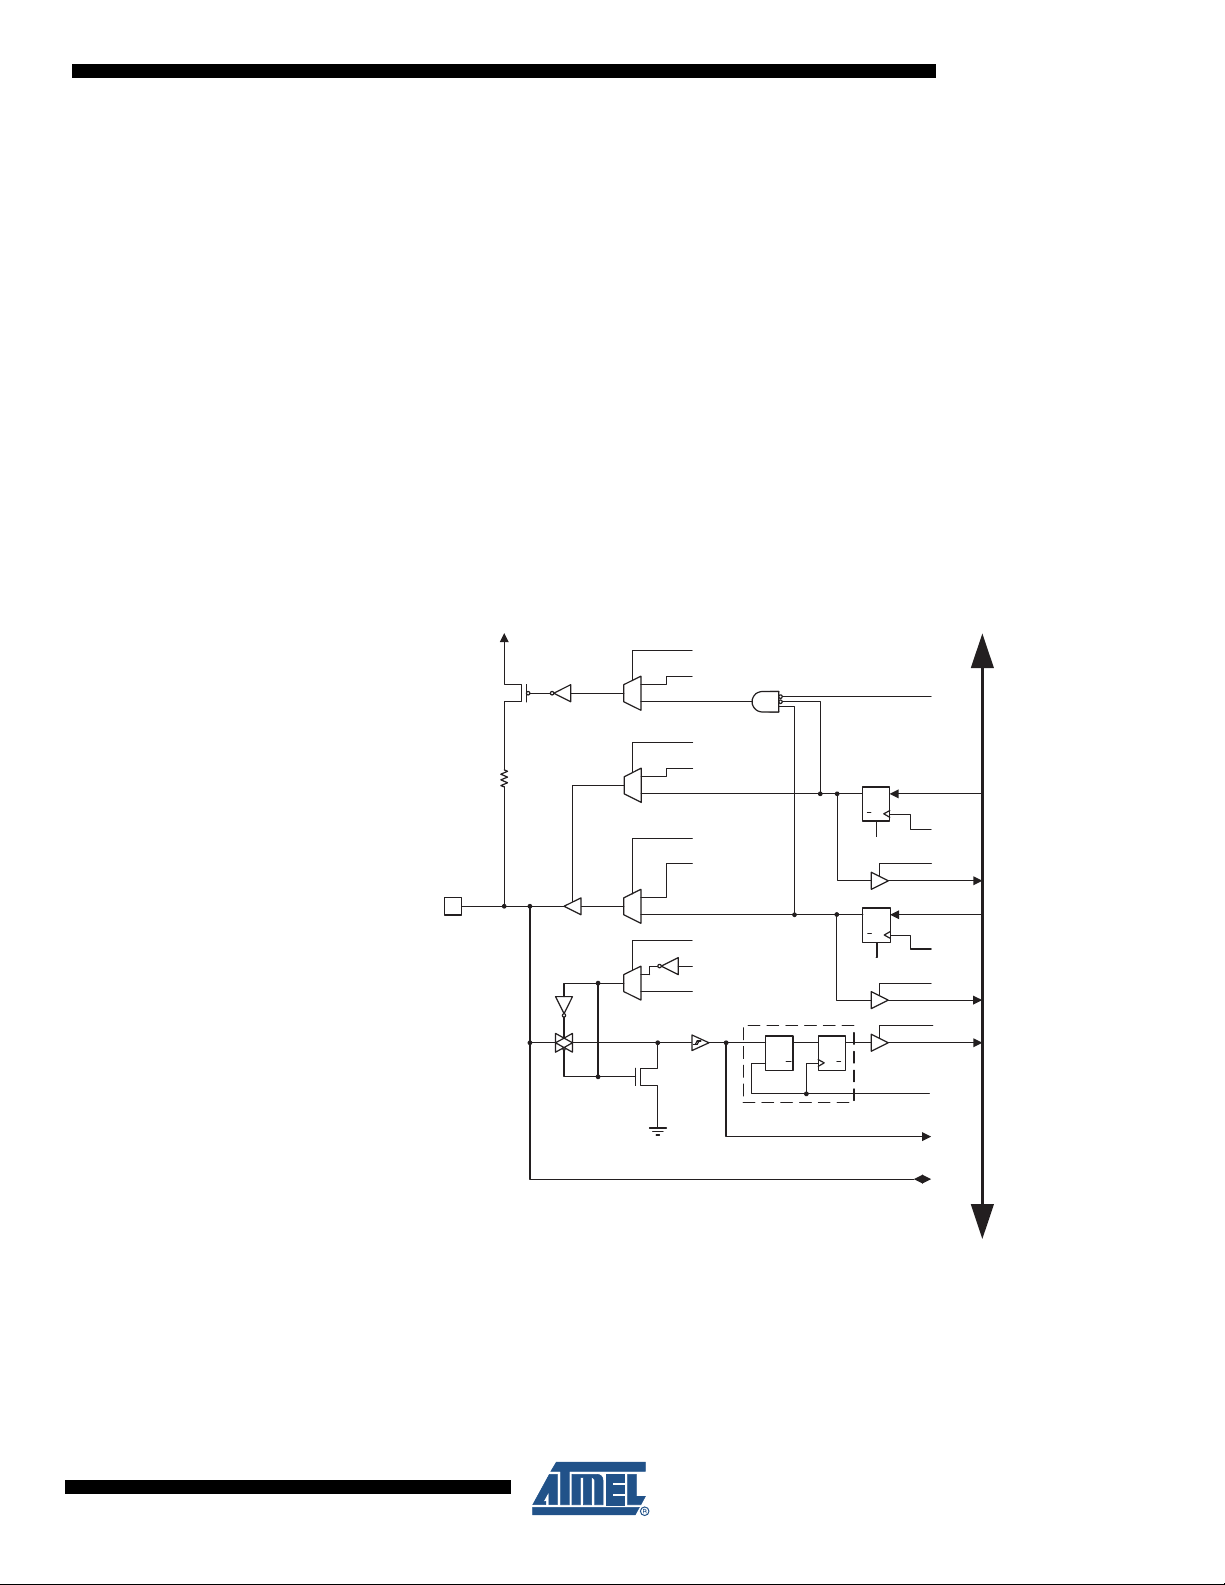
13.2.4 Unconnected Pins
clk
RPx
RRx
WPx
RDx
WDx
PUD
SYNCHRONIZER
WDx: WRITE DDRx
WPx: WRITE PORTx
RRx: READ PORTx REGISTER
RPx: READ PORTx PIN
PUD: PULLUP DISABLE
clk
I/O
: I/O CLOCK
RDx: READ DDRx
DLQ
Q
SET
CLR
0
1
0
1
0
1
DIxn
AIOxn
DIEOExn
PVOVxn
PVOExn
DDOVxn
DDOExn
PUOExn
PUOVxn
PUOExn: Pxn PULL-UP OVERRIDE ENABLE
PUOVxn: Pxn PULL-UP OVERRIDE VALUE
DDOExn: Pxn DATA DIRECTION OVERRIDE ENABLE
DDOVxn: Pxn DATA DIRECTION OVERRIDE VALUE
PVOExn: Pxn PORT VALUE OVERRIDE ENABLE
PVOVxn: Pxn PORT VALUE OVERRIDE VALUE
DIxn: DIGITAL INPUT PIN n ON PORTx
AIOxn: ANALOG INPUT/OUTPUT PIN n ON PORTx
RESET
RESET
Q
Q
D
CLR
Q
Q
D
CLR
Q
Q
D
CLR
PINxn
PORTxn
DDxn
DATA BU S
0
1
DIEOVxn
SLEEP
DIEOExn: Pxn DIGITAL INPUT-ENABLE OVERRIDE ENABLE
DIEOVxn: Pxn DIGITAL INPUT-ENABLE OVERRIDE VALUE
SLEEP: SLEEP CONTROL
Pxn
I/O
If some pins are unused, it is recommended to ensure that these pins have a defined level. Even
though most of the digital inputs are disabled in the deep sleep modes as described above, floating inputs should be avoided to reduce current consumption in all other modes where the digital
inputs are enabled (Reset, Active mode and Idle mode).
The simplest method to ensure a defined level of an unused pin, is to enable the internal pull-up.
In this case, the pull-up will be disabled during reset. If low power consumption during reset is
important, it is recommended to use an external pull-up or pull-down. Connecting unused pins
directly to VCC or GND is not recommended, since this may cause excessive currents if the pin
is accidentally configured as an output.
13.3 Alternate Port Functions
Most port pins have alternate functions in addition to being general digital I/Os. Figure 13-5
shows how the port pin control signals from the simplified Figure 13-2 can be overridden by
alternate functions. The overriding signals may not be present in all port pins, but the figure
serves as a generic description applicable to all port pins in the AVR microcontroller family.
ATmega64A
Figure 13-5. Alternate Port Functions
Note: 1. WPx, WDx, RLx, RPx, and RDx are common to all pins within the same port. clk
and PUD are common to all ports. All other signals are unique for each pin.
(1)
, SLEEP,
I/O
8160C–AVR–07/09
73
Page 74
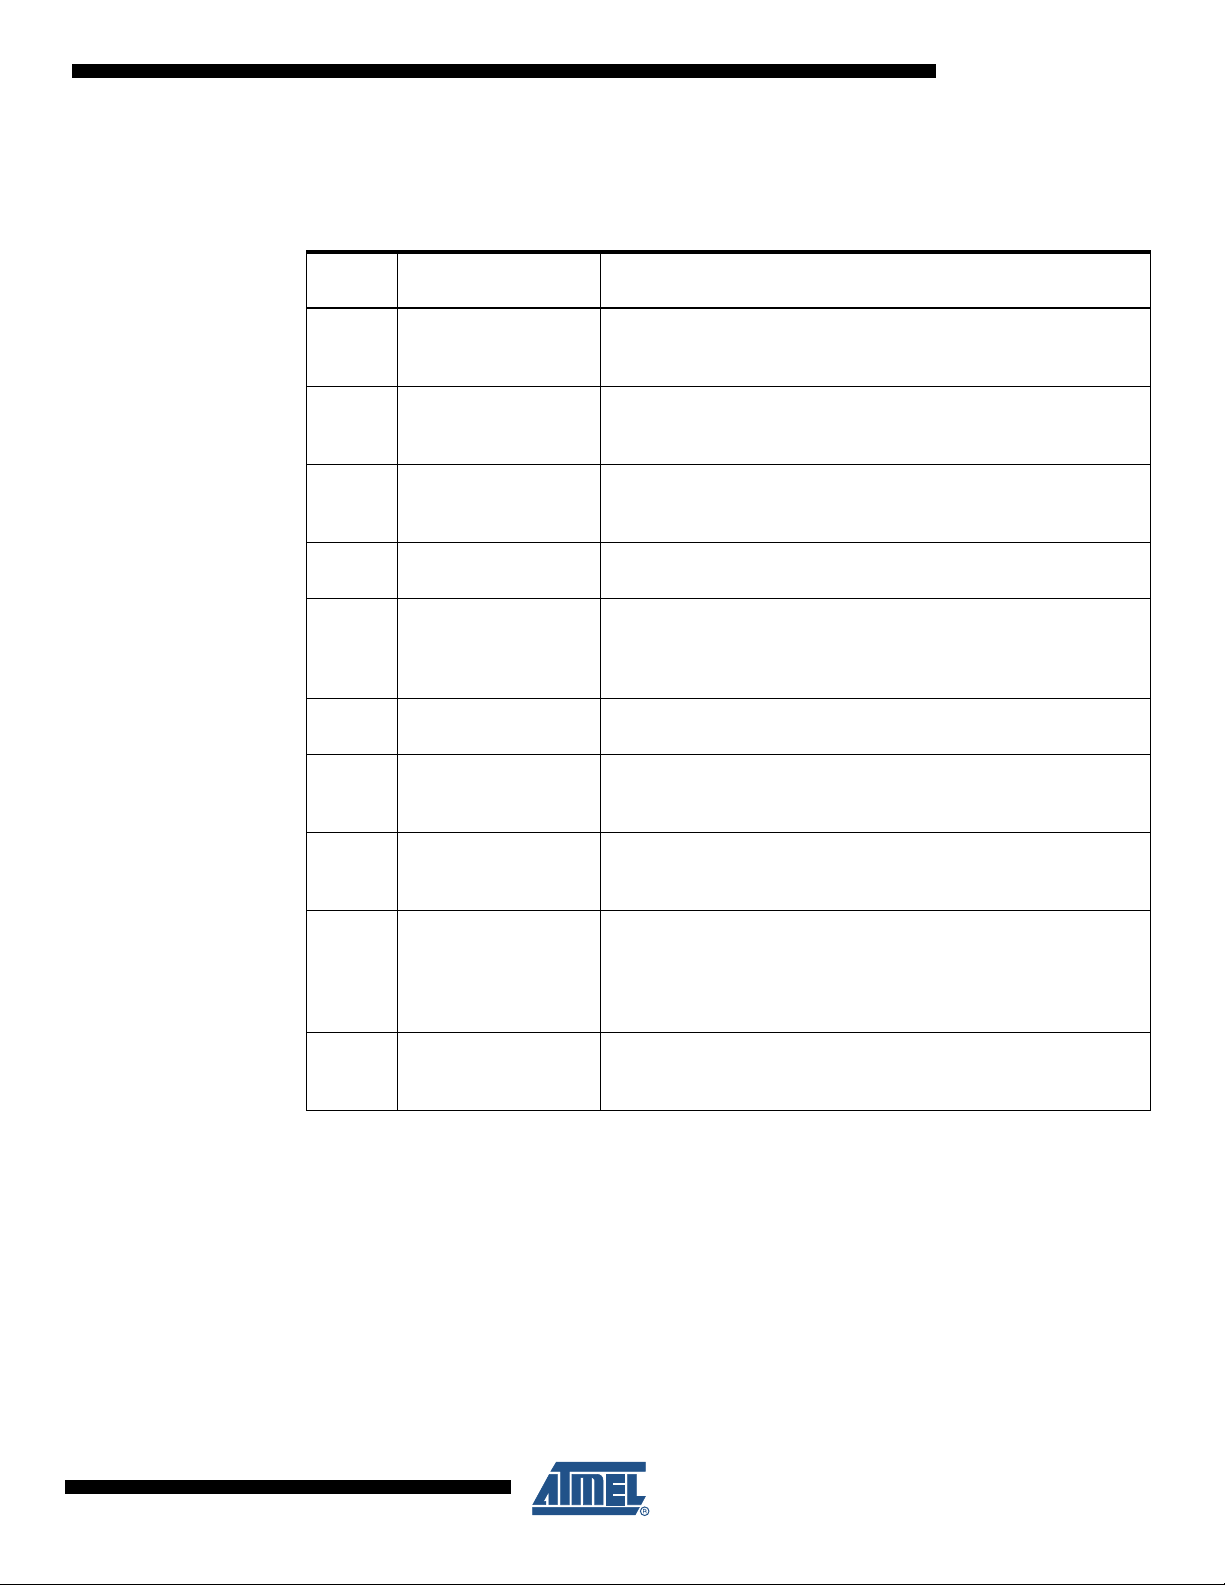
ATmega64A
Table 13-2 summarizes the function of the overriding signals. The pin and port indexes from Fig-
ure 13-5 are not shown in the succeeding tables. The overriding signals are generated internally
in the modules having the alternate function.
Table 13-2. Generic Description of Overriding Signals for Alternate Functions
Signal
Name Full Name Description
PUOE Pull-up Override
Enable
PUOV Pull-up Override Value If PUOE is set, the pull-up is enabled/disabled when PUOV is
DDOE Data Direction
Override Enable
DDOV Data Direction
Override Value
PVOE Port Value Override
Enable
PVOV Port Value Override
Val ue
DIEOE Digital Input Enable
Override Enable
DIEOV Digital Input Enable
Override Value
DI Digital Input This is the Digital Input to alternate functions. In the figure, the
AIO Analog Input/output This is the Analog Input/output to/from alternate functions. The
If this signal is set, the pull-up enable is controlled by the PUOV
signal. If this signal is cleared, the pull-up is enabled when {DDxn,
PORTxn, PUD} = 0b010.
set/cleared, regardless of the setting of the DDxn, PORTxn, and
PUD Register bits.
If this signal is set, the Output Driver Enable is controlled by the
DDOV signal. If this signal is cleared, the Output driver is enabled
by the DDxn Register bit.
If DDOE is set, the Output Driver is enabled/disabled when DDOV
is set/cleared, regardless of the setting of the DDxn Register bit.
If this signal is set and the Output Driver is enabled, the port value
is controlled by the PVOV signal. If PVOE is cleared, and the
Output Driver is enabled, the port Value is controlled by the
PORTxn Register bit.
If PVOE is set, the port value is set to PVOV, regardless of the
setting of the PORTxn Register bit.
If this bit is set, the Digital Input Enable is controlled by the DIEOV
signal. If this signal is cleared, the Digital Input Enable is
determined by MCU state (Normal mode, sleep modes).
If DIEOE is set, the Digital Input is enabled/disabled when DIEOV
is set/cleared, regardless of the MCU state (Normal mode, sleep
modes).
signal is connected to the output of the Schmitt Trigger but before
the synchronizer. Unless the Digital Input is used as a clock
source, the module with the alternate function will use its own
synchronizer.
signal is connected directly to the pad, and can be used bidirectionally.
8160C–AVR–07/09
The following subsections shortly describe the alternate functions for each port, and relate the
overriding signals to the alternate function. Refer to the alternate function description for further
details.
74
Page 75
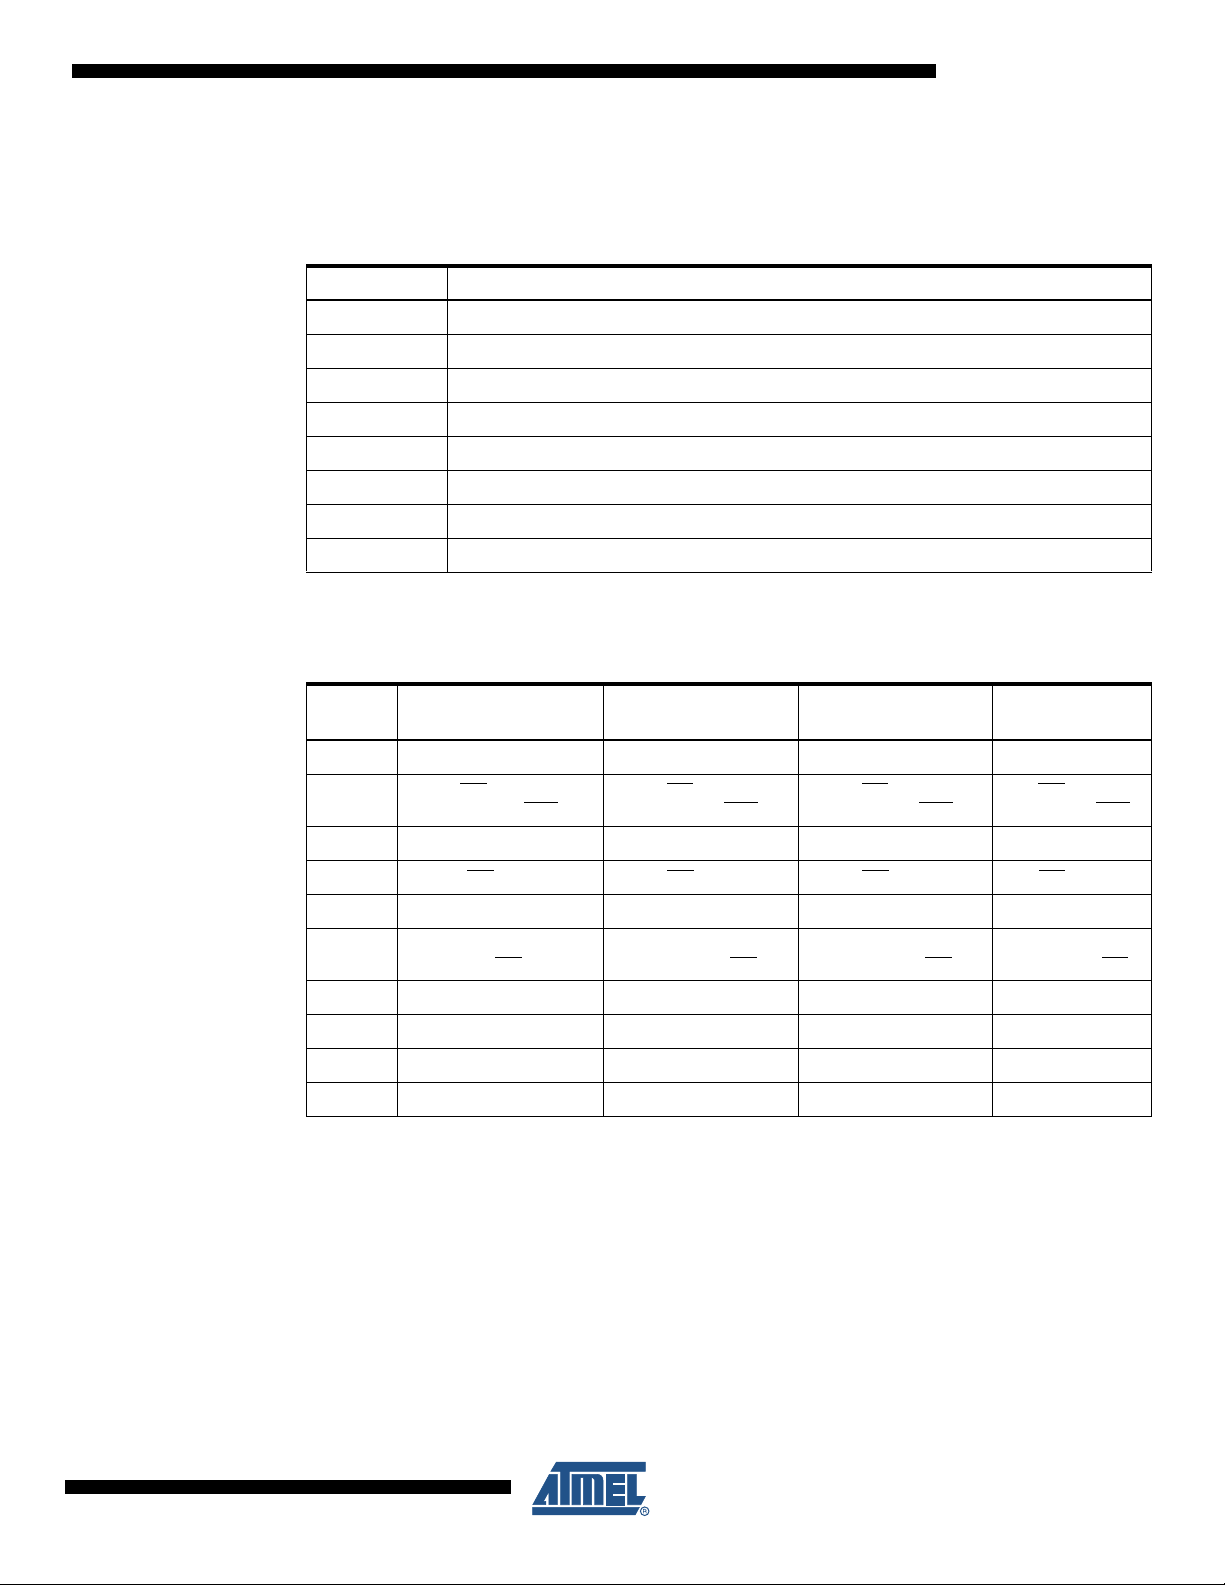
13.3.1 Alternate Functions of Port A
The Port A has an alternate function as the address low byte and data lines for the External
Memory Interface.
Table 13-3. Port A Pins Alternate Functions
Port Pin Alternate Function
PA7 AD7 (External memory interface address and data bit 7)
PA6 AD6 (External memory interface address and data bit 6)
PA5 AD5 (External memory interface address and data bit 5)
PA4 AD4 (External memory interface address and data bit 4)
PA3 AD3 (External memory interface address and data bit 3)
PA2 AD2 (External memory interface address and data bit 2)
PA1 AD1 (External memory interface address and data bit 1)
PA0 AD0 (External memory interface address and data bit 0)
Table 13-4 and Table 13-5 relates the alternate functions of Port A to the overriding signals
shown in Figure 13-5 on page 73.
ATmega64A
Table 13-4. Overriding Signals for Alternate Functions in PA7:PA4
Signal
Name PA7/AD7 PA6/AD6 PA5/AD5 PA4/AD4
PUOE
PUOV
DDOE
DDOV
PVOE
PVOV
DIEOE
DIEOV
DI
AIO
A7 • ADA | D7 OUTPUT
SRE SRE SRE SRE
~(WR | ADA
PORTA7 • PUD
WR | ADA WR | ADA WR | ADA WR | ADA
D7 INPUT D6 INPUT D5 INPUT D4 INPUT
(1)
) •
SRE SRE SRE SRE
SRE SRE SRE SRE
• WR
0000
0000
––––
~(WR | ADA) •
PORTA6 • PUD
A6 • ADA | D6
OUTPUT • WR
~(WR | ADA) •
PORTA5 • PUD
A5 • ADA | D5
OUTPUT • WR
~(WR | ADA) •
PORTA4 • PUD
A4 • ADA | D4
OUTPUT • WR
8160C–AVR–07/09
75
Page 76
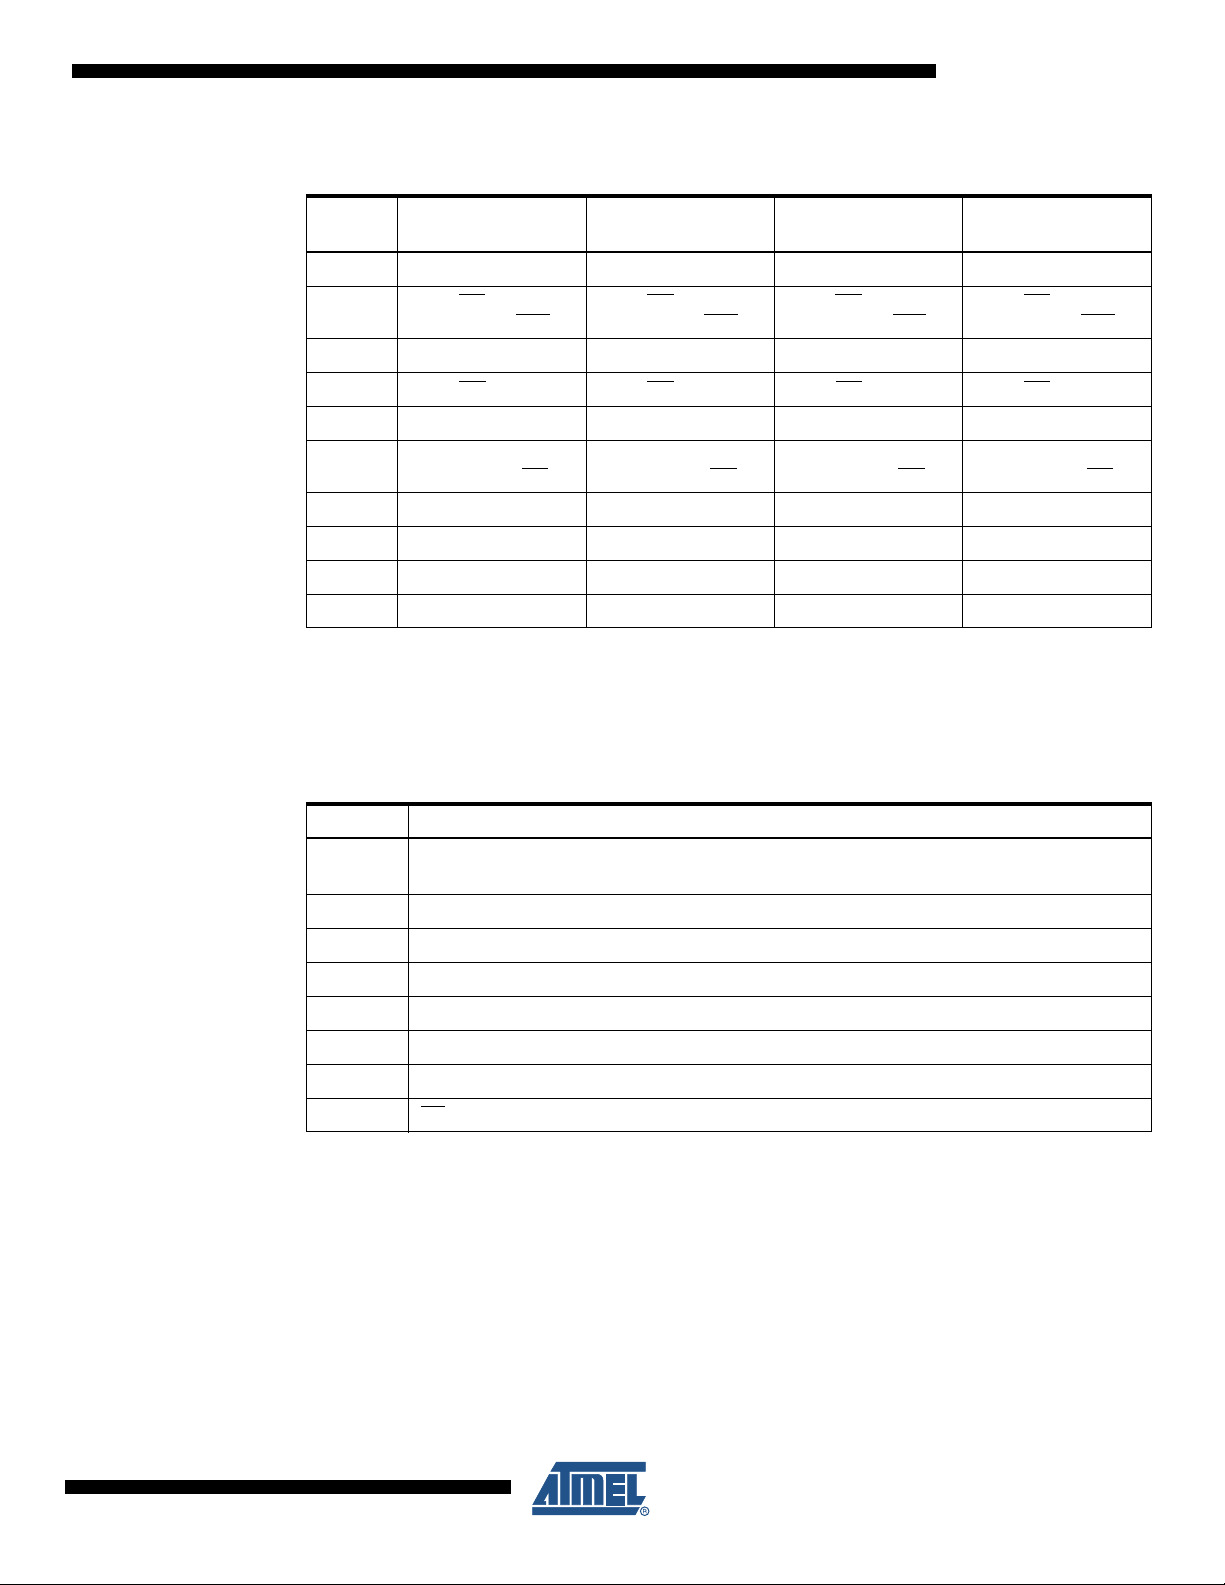
ATmega64A
Table 13-5. Overriding Signals for Alternate Functions in PA3:PA0
Signal
Name PA3/AD3 PA2/AD2 PA1/AD1 PA0/AD0
PUOE
PUOV
DDOE
DDOV
PVOE
PVOV
DIEOE
DIEOV
DI
AIO
Note: 1. ADA is short for ADdress Active and represents the time when address is output. See “Exter-
nal Memory Interface” on page 23 for details.
13.3.2 Alternate Functions of Port B
The Port B pins with alternate functions are shown in Table 13-6.
(1)
SRE SRE SRE SRE
~(WR | ADA) •
PORTA3 • PUD
SRE SRE SRE SRE
WR | ADA WR | ADA WR | ADA WR | ADA
SRE SRE SRE SRE
A3 • ADA | D3
OUTPUT • WR
0000
0000
D3 INPUT D2 INPUT D1 INPUT D0 INPUT
––––
~(WR | ADA) •
PORTA2 • PUD
A2• ADA | D2
OUTPUT • WR
~(WR | ADA) •
PORTA1 • PUD
A1 • ADA | D1
OUTPUT • WR
~(WR | ADA) •
PORTA0 • PUD
A0 • ADA | D0
OUTPUT • WR
Table 13-6. Port B Pins Alternate Functions
Port Pin Alternate Functions
(1)
PB7 OC2/OC1C
(Output Compare and PWM Output for Timer/Counter2 or Output Compare
and PWM Output C for Timer/Counter1)
PB6 OC1B (Output Compare and PWM Output B for Timer/Counter1)
PB5 OC1A (Output Compare and PWM Output A for Timer/Counter1)
PB4 OC0 (Output Compare and PWM Output for Timer/Counter0)
PB3 MISO (SPI Bus Master Input/Slave Output)
PB2 MOSI (SPI Bus Master Output/Slave Input)
PB1 SCK (SPI Bus Serial Clock)
PB0 SS
(SPI Slave Select input)
Note: 1. OC1C not applicable in ATmega103 compatibility mode.
The alternate pin configuration is as follows:
• OC2/OC1C, Bit 7
OC2, Output Compare Match output: The PB7 pin can serve as an external output for the
Timer/Counter2 Output Compare. The pin has to be configured as an output (DDB7 set (one)) to
serve this function. The OC2 pin is also the output pin for the PWM mode timer function.
OC1C, Output Compare Match C output: The PB7 pin can serve as an external output for the
Timer/Counter1 Output Compare C. The pin has to be configured as an output (DDB7 set (one))
to serve this function. The OC1C pin is also the output pin for the PWM mode timer function.
8160C–AVR–07/09
76
Page 77
ATmega64A
• OC1B, Bit 6
OC1B, Output Compare Match B output: The PB6 pin can serve as an external output for the
Timer/Counter1 Output Compare B. The pin has to be configured as an output (DDB6 set (one))
to serve this function. The OC1B pin is also the output pin for the PWM mode timer function.
• OC1A, Bit 5
OC1A, Output Compare Match A output: The PB5 pin can serve as an external output for the
Timer/Counter1 Output Compare A. The pin has to be configured as an output (DDB5 set (one))
to serve this function. The OC1A pin is also the output pin for the PWM mode timer function.
• OC0, Bit 4
OC0, Output Compare Match output: The PB4 pin can serve as an external output for the
Timer/Counter0 Output Compare. The pin has to be configured as an output (DDB4 set (one)) to
serve this function. The OC0 pin is also the output pin for the PWM mode timer function.
• MISO – Port B, Bit 3
MISO: Master Data input, Slave Data output pin for SPI channel. When the SPI is enabled as a
Master, this pin is configured as an input regardless of the setting of DDB3. When the SPI is
enabled as a Slave, the data direction of this pin is controlled by DDB3. When the pin is forced to
be an input, the pull-up can still be controlled by the PORTB3 bit.
• MOSI – Port B, Bit 2
MOSI: SPI Master Data output, Slave Data input for SPI channel. When the SPI is enabled as a
Slave, this pin is configured as an input regardless of the setting of DDB2. When the SPI is
enabled as a Master, the data direction of this pin is controlled by DDB2. When the pin is forced
to be an input, the pull-up can still be controlled by the PORTB2 bit.
• SCK – Port B, Bit 1
SCK: Master Clock output, Slave Clock input pin for SPI channel. When the SPI is enabled as a
Slave, this pin is configured as an input regardless of the setting of DDB1. When the SPI is
enabled as a Master, the data direction of this pin is controlled by DDB1. When the pin is forced
to be an input, the pull-up can still be controlled by the PORTB1 bit.
•SS
– Port B, Bit 0
SS
: Slave Port Select input. When the SPI is enabled as a Slave, this pin is configured as an
input regardless of the setting of DDB0. As a Slave, the SPI is activated when this pin is driven
low. When the SPI is enabled as a Master, the data direction of this pin is controlled by DDB0.
When the pin is forced to be an input, the pull-up can still be controlled by the PORTB0 bit.
Table 13-7 and Table 13-8 relate the alternate functions of Port B to the overriding signals
shown in Figure 13-5 on page 73. SPI MSTR INPUT and SPI SLAVE OUTPUT constitute the
MISO signal, while MOSI is divided into SPI MSTR OUTPUT and SPI SLAVE INPUT.
8160C–AVR–07/09
77
Page 78
ATmega64A
Table 13-7. Overriding Signals for Alternate Functions in PB7:PB4
Signal
Name PB7/OC2/OC1C PB6/OC1B PB5/OC1A PB4/OC0
PUOE0 000
PUOV0 000
DDOE 0 0 0 0
DDOV 0 0 0 0
PVOE OC2/OC1C ENABLE
PVOV OC2/OC1C
DIEOE0 000
DIEOV0 000
DI– –––
AIO– –––
Note: 1. See “Output Compare Modulator (OCM1C2)” on page 162 for details. OC1C does not exist in
ATmega103 compatibility mode.
(1)
(1)
OC1B ENABLE OC1A ENABLE OC0 ENABLE
OC1B OC1A OC0B
Table 13-8. Overriding Signals for Alternate Functions in PB3:PB0
Signal
Name PB3/MISO PB2/MOSI PB1/SCK PB0/SS
PUOE SPE • MSTR SPE • MSTR SPE • MSTR SPE • MSTR
PUOV PORTB3 • PUD PORTB2 • PUD PORTB1 • PUD PORTB0 • PUD
DDOE SPE • MSTR SPE • MSTR SPE • MSTR SPE • MSTR
DDOV 0 0 0 0
PVOE SPE • MSTR
PVOV SPI SLAVE OUTPUT SPI MSTR OUTPUT SCK OUTPUT 0
DIEOE 0 0 0 0
DIEOV 0 0 0 0
DI SPI MSTR INPUT SPI SLAVE INPUT SCK INPUT SPI SS
AIO – – – –
SPE • MSTR SPE • MSTR 0
8160C–AVR–07/09
78
Page 79
13.3.3 Alternate Functions of Port C
In ATmega103 compatibility mode, Port C is output only. The Port C has an alternate function as
the address high byte for the External Memory Interface
Table 13-9. Port C Pins Alternate Functions
Port Pin Alternate Function
Table 13-10 and Table 13-11 relate the alternate functions of Port C to the overriding signals
shown in Figure 13-5 on page 73.
ATmega64A
PC7 A15
PC6 A14
PC5 A13
PC4 A12
PC3 A11
PC2 A10
PC1 A9
PC0 A8
Table 13-10. Overriding Signals for Alternate Functions in PC7:PC4
Signal Name PC7/A15 PC6/A14 PC5/A13 PC4/A12
(1)
PUOE SRE • (XMM
PUOV0 000
DDOE SRE • (XMM<1) SRE • (XMM<2) SRE • (XMM<3) SRE • (XMM<4)
DDOV 1 1 1 1
PVOE SRE • (XMM<1) SRE • (XMM<2) SRE • (XMM<3) SRE • (XMM<4)
PVOV A11 A10 A9 A8
DIEOE0 000
DIEOV0 000
DI– –––
AIO– –––
<1) SRE • (XMM<2) SRE • (XMM<3) SRE • (XMM<4)
8160C–AVR–07/09
79
Page 80
ATmega64A
Table 13-11. Overriding Signals for Alternate Functions in PC3:PC0
Signal Name PC3/A11 PC2/A10 PC1/A9 PC0/A8
PUOE SRE • (XMM<5) SRE • (XMM<6) SRE • (XMM<7) SRE • (XMM<7)
PUOV0000
DDOE SRE • (XMM<5) SRE • (XMM<6) SRE • (XMM<7) SRE • (XMM<7)
DDOV 1 1 1 1
PVOE SRE • (XMM<5) SRE • (XMM<6) SRE • (XMM<7) SRE • (XMM<7)
PVOV A11 A10 A9 A8
DIEOE0000
DIEOV0000
DI––––
AIO––––
Note: 1. XMM = 0 in ATmega103 compatibility mode.
13.3.4 Alternate Functions of Port D
The Port D pins with alternate functions are shown in Table 13-12.
Table 13-12. Port D Pins Alternate Functions
Port Pin Alternate Function
PD7 T2 (Timer/Counter2 Clock Input)
PD6 T1 (Timer/Counter1 Clock Input)
PD5 XCK1
PD4 ICP1 (Timer/Counter1 Input Capture Pin)
PD3 INT3/TXD1
PD2 INT2/RXD1
PD1 INT1/SDA
PD0 INT0/SCL
(1)
(USART1 External Clock Input/Output)
(1)
(External Interrupt3 Input or UART1 Transmit Pin)
(1)
(External Interrupt2 Input or UART1 Receive Pin)
(1)
(External Interrupt1 Input or TWI Serial DAta)
(1)
(External Interrupt0 Input or TWI Serial CLock)
(1)
8160C–AVR–07/09
Note: 1. XCK1, TXD1, RXD1, SDA, and SCL not applicable in ATmega103 compatibility mode.
The alternate pin configuration is as follows:
• T2 – Port D, Bit 7
T2, Timer/Counter2 Counter Source.
• T1 – Port D, Bit 6
T1, Timer/Counter1 Counter Source.
• XCK1 – Port D, Bit 5
XCK1, USART1 External Clock. The Data Direction Register (DDD5) controls whether the clock
is output (DDD5 set) or input (DDD5 cleared). The XCK1 pin is active only when the USART1
operates in synchronous mode.
• ICP1 – Port D, Bit 4
ICP1 – Input Capture Pin1: The PD4 pin can act as an Input Capture pin for Timer/Counter1.
80
Page 81
ATmega64A
• INT3/TXD1 – Port D, Bit 3
INT3, External Interrupt Source 3: The PD3 pin can serve as an External Interrupt source to the
MCU.
TXD1, Transmit Data (Data output pin for the USART1). When the USART1 transmitter is
enabled, this pin is configured as an output regardless of the value of DDD3.
• INT2/RXD1 – Port D, Bit 2
INT2, External Interrupt source 2. The PD2 pin can serve as an External Interrupt source to the
MCU.
RXD1, Receive Data (Data input pin for the USART1). When the USART1 receiver is enabled
this pin is configured as an input regardless of the value of DDD2. When the USART forces this
pin to be an input, the pull-up can still be controlled by the PORTD2 bit.
• INT1/SDA – Port D, Bit 1
INT1, External Interrupt Source 1. The PD1 pin can serve as an External Interrupt source to the
MCU.
SDA, Two-wire Serial Interface Data: When the TWEN bit in TWCR is set (one) to enable the
Two-wire Serial Interface, pin PD1 is disconnected from the port and becomes the serial data I/O
pin for the Two-wire Serial Interface. In this mode, there is a spike filter on the pin to suppress
spikes shorter than 50 ns on the input signal, and the pin is driven by an open drain driver with
slew-rate limitation.
•INT0/SCL – Port D, Bit 0
INT0, External Interrupt Source 0. The PD0 pin can serve as an External Interrupt source to the
MCU.
SCL, Two-wire Serial Interface Clock: When the TWEN bit in TWCR is set (one) to enable the
Two-wire Serial Interface, pin PD0 is disconnected from the port and becomes the serial clock
I/O pin for the Two-wire Serial Interface. In this mode, there is a spike filter on the pin to suppress spikes shorter than 50 ns on the input signal, and the pin is driven by an open drain driver
with slew-rate limitation.
Table 13-13 and Table 13-14 relates the alternate functions of Port D to the overriding signals
shown in Figure 13-5 on page 73.
8160C–AVR–07/09
81
Page 82
ATmega64A
Table 13-13. Overriding Signals for Alternate Functions PD7:PD4
Signal Name PD7/T2 PD6/T1 PD5/XCK1 PD4/ICP1
PUOE 0 0 0 0
PUOV 0 0 0 0
DDOE 0 0 0 0
DDOV 0 0 0 0
PVOE 0 0 UMSEL1 0
PVOV 0 0 XCK1 OUTPUT 0
DIEOE 0 0 0 0
DIEOV 0 0 0 0
DI T2 INPUT T1 INPUT XCK1 INPUT ICP1 INPUT
AIO – – – –
Table 13-14. Overriding Signals for Alternate Functions in PD3:PD0
Signal Name PD3/INT3/TXD1 PD2/INT2/RXD1 PD1/INT1/SDA PD0/INT0/SCL
PUOE TXEN1 RXEN1 TWEN TWEN
PUOV 0 PORTD2 • PUD
PORTD1 • PUD PORTD0 • PUD
(1)
DDOE TXEN1 RXEN1 TWEN TWEN
DDOV 1 0 SDA_OUT SCL_OUT
PVOE TXEN1 0 TWEN TWEN
PVOV TXD1 0 0 0
DIEOE INT3 ENABLE INT2 ENABLE INT1 ENABLE INT0 ENABLE
DIEOV 1 1 1 1
DI INT3 INPUT INT2 INPUT/RXD1 INT1 INPUT INT0 INPUT
AIO – – SDA INPUT SCL INPUT
Note: 1. When enabled, the Two-wire Serial Interface enables Slew-rate controls on the output pins
PD0 and PD1. This is not shown on the figure. In addition, spike filters are connected between
the AIO outputs shown in the port figure and the digital logic of the TWI module.
8160C–AVR–07/09
82
Page 83
13.3.5 Alternate Functions of Port E
The Port E pins with alternate functions are shown in Table 13-15.
Table 13-15. Port E Pins Alternate Functions
Port Pin Alternate Function
PE7 INT7/ICP3
PE6 INT6/ T3
PE5 INT5/OC3C
Timer/Counter3)
PE4 INT4/OC3B
Timer/Counter3)
PE3 AIN1/OC3A
for Timer/Counter3)
PE2 AIN0/XCK0
PE1 PDO/TXD0 (Programming Data Output or UART0 Transmit Pin)
PE0 PDI/RXD0 (Programming Data Input or UART0 Receive Pin)
Note: 1. ICP3, T3, OC3C, OC3B, OC3B, OC3A, and XCK0 not applicable in ATmega103 compatibility
mode.
ATmega64A
(1)
(External Interrupt 7 Input or Timer/Counter3 Input Capture Pin)
(1)
(External Interrupt 6 Input or Timer/Counter3 Clock Input)
(1)
(External Interrupt 5 Input or Output Compare and PWM Output C for
(1)
(External Interrupt 4 Input or Output Compare and PWM Output B for
(1)
(Analog Comparator Negative Input or Output Compare and PWM Output A
(1)
(Analog Comparator Positive Input or USART0 external clock input/output)
• INT7/ICP3 – Port E, Bit 7
INT7, External Interrupt Source 7: The PE7 pin can serve as an External Interrupt source.
ICP3 – Input Capture Pin3: The PE7 pin can act as an Input Capture pin for Timer/Counter3.
• INT6/T3 – Port E, Bit 6
INT6, External Interrupt Source 6: The PE6 pin can serve as an External Interrupt source.
T3, Timer/Counter3 Counter Source.
• INT5/OC3C – Port E, Bit 5
INT5, External Interrupt Source 5: The PE5 pin can serve as an External Interrupt source.
OC3C, Output Compare Match C output: The PE5 pin can serve as an external output for the
Timer/Counter3 Output Compare C. The pin has to be configured as an output (DDE5 set – one)
to serve this function. The OC3C pin is also the output pin for the PWM mode timer function.
• INT4/OC3B – Port E, Bit 4
INT4, External Interrupt Source 4: The PE4 pin can serve as an External Interrupt source.
OC3B, Output Compare Match B output: The PE4 pin can serve as an external output for the
Timer/Counter3 Output Compare B. The pin has to be configured as an output (DDE4 set – one)
to serve this function. The OC3B pin is also the output pin for the PWM mode timer function.
• AIN1/OC3A – Port E, Bit 3
AIN1 – Analog Comparator Negative input. This pin is directly connected to the negative input of
the Analog Comparator.
8160C–AVR–07/09
OC3A, Output Compare Match A output: The PE3 pin can serve as an external output for the
Timer/Counter3 Output Compare A. The pin has to be configured as an output (DDE3 set – one)
to serve this function. The OC3A pin is also the output pin for the PWM mode timer function.
83
Page 84
ATmega64A
• AIN0/XCK0 – Port E, Bit 2
AIN0 – Analog Comparator Positive input. This pin is directly connected to the positive input of
the Analog Comparator.
XCK0, USART0 External Clock. The Data Direction Register (DDE2) controls whether the clock
is output (DDE2 set) or input (DDE2 cleared). The XCK0 pin is active only when the USART0
operates in synchronous mode.
• PDO/TXD0 – Port E, Bit 1
PDO, SPI Serial Programming Data output. During Serial Program Downloading, this pin is used
as data output line for the ATmega64A.
TXD0, UART0 Transmit Pin.
• PDI/RXD0 – Port E, Bit 0
PDI, SPI Serial Programming Data input. During serial program downloading, this pin is used as
data input line for the ATmega64A.
RXD0, USART0 Receive pin. Receive Data (Data Input pin for the USART0). When the
USART0 Receiver is enabled this pin is configured as an input regardless of the value of
DDRE0. When the USART0 forces this pin to be an input, a logical one in PORTE0 will turn on
the internal pull-up.
Table 13-16 and Table 13-17 relates the alternate functions of Port E to the overriding signals
shown in Figure 13-5 on page 73.
Table 13-16. Overriding Signals for Alternate Functions PE7:PE4
Signal
Name PE7/INT7/ICP3 PE6/INT6/T3 PE5/INT5/OC3C PE4/INT4/OC3B
PUOE0000
PUOV0000
DDOE 0 0 0 0
DDOV 0 0 0 0
PVOE 0 0 OC3C ENABLE OC3B ENABLE
PVOV 0 0 OC3C OC3B
DIEOE INT7 ENABLE INT6 ENABLE INT5 ENABLE INT4 ENABLE
DIEOV1111
DI INT7 INPUT/ICP3
INPUT
AIO––––
INT7 INPUT/T3
INPUT
INT5 INPUT INT4 INPUT
8160C–AVR–07/09
84
Page 85
Table 13-17. Overriding Signals for Alternate Functions in PE3:PE0
Signal
Name PE3/AIN1/OC3A PE2/AIN0/XCK0 PE1/PDO/TXD0 PE0/PDI/RXD0
PUOE 0 0 TXEN0 RXEN0
PUOV000PORTE0 • PUD
DDOE 0 0 TXEN0 RXEN0
DDOV0010
PVOE OC3B ENABLE UMSEL0 TXEN0 0
PVOV OC3B XCK0 OUTPUT TXD0 0
DIEOE0000
DIEOV0000
DI 0 XCK0 INPUT – RXD0
AIO AIN1 INPUT AIN0 INPUT – –
13.3.6 Alternate Functions of Port F
The Port F has an alternate function as analog input for the ADC as shown in Table 13-18. If
some Port F pins are configured as outputs, it is essential that these do not switch when a conversion is in progress. This might corrupt the result of the conversion. In ATmega103
compatibility mode Port F is input only. If the JTAG interface is enabled, the pull-up resistors on
pins PF7(TDI), PF5(TMS) and PF4(TCK) will be activated even if a reset occurs.
ATmega64A
Table 13-18. Port F Pins Alternate Functions
Port Pin Alternate Function
PF7 ADC7/TDI (ADC input channel 7 or JTAG Test Data Input)
PF6 ADC6/TDO (ADC input channel 6 or JTAG Test Data Output)
PF5 ADC5/TMS (ADC input channel 5 or JTAG Test mode Select)
PF4 ADC4/TCK (ADC input channel 4 or JTAG Test Clock)
PF3 ADC3 (ADC input channel 3)
PF2 ADC2 (ADC input channel 2)
PF1 ADC1 (ADC input channel 1)
PF0 ADC0 (ADC input channel 0)
• TDI, ADC7 – Port F, Bit 7
ADC7, Analog to Digital Converter, Channel 7
.
TDI, JTAG Test Data In: Serial input data to be shifted in to the Instruction Register or Data Register (scan chains). When the JTAG interface is enabled, this pin can not be used as an I/O pin.
• TDO, ADC6 – Port F, Bit 6
ADC6, Analog to Digital Converter, Channel 6
.
TDO, JTAG Test Data Out: Serial output data from Instruction Register or Data Register. When
the JTAG interface is enabled, this pin can not be used as an I/O pin.
8160C–AVR–07/09
The TDO pin is tri-stated unless TAP states that shift out data are entered.
85
Page 86
ATmega64A
• TMS, ADC5 – Port F, Bit 5
ADC5, Analog to Digital Converter, Channel 5
TMS, JTAG Test mode Select: This pin is used for navigating through the TAP-controller state
machine. When the JTAG interface is enabled, this pin can not be used as an I/O pin.
• TCK, ADC4 – Port F, Bit 4
ADC4, Analog to Digital Converter, Channel 4
TCK, JTAG Test Clock: JTAG operation is synchronous to TCK. When the JTAG interface is
enabled, this pin can not be used as an I/O pin.
• ADC3 - ADC0 – Port F, Bit 3:0
Analog to Digital Converter, Channel 3:0.
Table 13-19. Overriding Signals for Alternate Functions in PF7:PF4
Signal
Name PF7/ADC7/TDI PF6/ADC6/TDO PF5/ADC5/TMS PF4/ADC4/TCK
PUOE JTAGEN JTAGEN JTAGEN JTAGEN
PUOV1011
D DO E J TAG E N J TA GE N J TAG E N J TAG E N
.
.
DDOV 0 SHIFT_IR +
SHIFT_DR
PVOE 0 JTAGEN 0 0
PVOV 0 TDO 0 0
D IE OE J TAG E N J TA GE N J TA GE N J TAG E N
DIEOV0000
DI––––
AIO TDI/ADC7 INPUT ADC6 INPUT TMS/ADC5 INPUT TCKADC4 INPUT
00
8160C–AVR–07/09
86
Page 87

Table 13-20. Overriding Signals for Alternate Functions in PF3:PF0
Signal
Name PF3/ADC3 PF2/ADC2 PF1/ADC1 PF0/ADC0
PUOE0000
PUOV0000
DDOE 0 0 0 0
DDOV 0 0 0 0
PVOE0000
PVOV0000
DIEOE0000
DIEOV0000
DI––––
AIO ADC3 INPUT ADC2 INPUT ADC1 INPUT ADC0 INPUT
13.3.7 Alternate Functions of Port G
In ATmega103 compatibility mode, only the alternate functions are the defaults for Port G, and
Port G cannot be used as General Digital Port Pins. The alternate pin configuration is as follows:
ATmega64A
Table 13-21. Port G Pins Alternate Functions
Port Pin Alternate Function
PG4 TOSC1 (RTC Oscillator Timer/Counter0)
PG3 TOSC2 (RTC Oscillator Timer/Counter0)
PG2 ALE (Address Latch Enable to external memory)
PG1 RD (Read strobe to external memory)
PG0 WR
(Write strobe to external memory)
• TOSC1 – Port G, Bit 4
TOSC2, Timer Oscillator pin 1: When the AS0 bit in ASSR is set (one) to enable asynchronous
clocking of Timer/Counter0, pin PG4 is disconnected from the port, and becomes the inverting
output of the Oscillator amplifier. In this mode, a crystal Oscillator is connected to this pin, and
the pin can not be used as an I/O pin.
• TOSC2 – Port G, Bit 3
TOSC2, Timer Oscillator pin 2: When the AS0 bit in ASSR is set (one) to enable asynchronous
clocking of Timer/Counter0, pin PG3 is disconnected from the port, and becomes the input of the
inverting Oscillator amplifier. In this mode, a crystal Oscillator is connected to this pin, and the
pin cannot be used as an I/O pin.
• ALE – Port G, Bit 2
ALE is the external data memory Address Latch Enable signal.
8160C–AVR–07/09
•RD
– Port G, Bit 1
RD
is the external data memory read control strobe.
87
Page 88
ATmega64A
•WR – Port G, Bit 0
WR
is the external data memory write control strobe.
Table 13-22 and Table 13-23 relates the alternate functions of Port G to the overriding signals
shown in Figure 13-5 on page 73.
Table 13-22. Overriding Signals for Alternate Functions in PG4:PG1
Signal Name PG4/TOSC1 PG3/TOSC2 PG2/ALE PG1/RD
PUOE AS0 AS0 SRE SRE
PUOV 0 0 0 0
DDOE AS0 AS0 SRE SRE
DDOV 0 0 1 1
PVOE 0 0 SRE SRE
PVOV 0 0 ALE RD
DIEOE AS0 AS0 0 0
DIEOV 0 0 0 0
DI – – – –
AIO T/C0 OSC INPUT T/C0 OSC OUTPUT – –
Table 13-23. Overriding Signals for Alternate Functions in PG0
Signal Name PG0/WR
PUOE SRE
PUOV 0
DDOE SRE
DDOV 1
PVOE SRE
PVOV WR
DIEOE 0
DIEOV 0
DI –
AIO –
13.4 Register Description
13.4.1 PORTA – Port A Data Register
Bit 76543210
0x1B (0x3B)
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
8160C–AVR–07/09
PORTA7 PORTA6 PORTA5 PORTA4 PORTA3 PORTA2 PORTA1 PORTA0 PORTA
88
Page 89
13.4.2 DDRA – Port A Data Direction Register
Bit 76543210
0x1A (0x3A) DDA7 DDA6 DDA5 DDA4 DDA3 DDA2 DDA1 DDA0 DDRA
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
13.4.3 PINA – Port A Input Pins Address
Bit 76543210
0x19 (0x39) PINA7 PINA6 PINA5 PINA4 PINA3 PINA2 PINA1 PINA0 PINA
Read/WriteRRRRRRRR
Initial Value N/A N/A N/A N/A N/A N/A N/A N/A
13.4.4 PORTB – Port B Data Register
Bit 76543210
0x18 (0x38)
Read/WriteR/WR/WR/WR/WR/WR/WR/WR/W
Initial Value 0 0 0 0 0 0 0 0
PORTB7 PORTB6 PORTB5 PORTB4 PORTB3 PORTB2 PORTB1 PORTB0 PORTB
13.4.5 DDRB – Port B Data Direction Register
Bit 76543210
0x17 (0x37) DDB7 DDB6 DDB5 DDB4 DDB3 DDB2 DDB1 DDB0 DDRB
Read/WriteR/WR/WR/WR/WR/WR/WR/WR/W
Initial Value 0 0 0 0 0 0 0 0
ATmega64A
13.4.6 PINB – Port B Input Pins Address
Bit 76543210
0x16 (0x36) PINB7 PINB6 PINB5 PINB4 PINB3 PINB2 PINB1 PINB0 PINB
Read/WriteRRRRRRRR
Initial Value N/A N/A N/A N/A N/A N/A N/A N/A
13.4.7 PORTC – Port C Data Register
Bit 76543210
0x15 (0x35)
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
PORTC7 PORTC6 PORTC5 PORTC4 PORTC3 PORTC2 PORTC1 PORTC0 PORTC
13.4.8 DDRC – Port C Data Direction Register
Bit 76543210
0x14 (0x34) DDC7 DDC6 DDC5 DDC4 DDC3 DDC2 DDC1 DDC0 DDRC
Read/WriteR/WR/WR/WR/WR/WR/WR/WR/W
Initial Value 0 0 0 0 0 0 0 0
13.4.9 PINC – Port C Input Pins Address
Bit 76543210
0x13 (0x33) PINC7 PINC6 PINC5 PINC4 PINC3 PINC2 PINC1 PINC0 PINC
Read/WriteRRRRRRRR
Initial Value N/A N/A N/A N/A N/A N/A N/A N/A
8160C–AVR–07/09
In ATmega103 compatibility mode, DDRC and PINC Registers are initialized to being Push-pull
Zero Output. The port pins assumes their Initial Value, even if the clock is not running. Note that
89
Page 90
the DDRC and PINC registers are available in ATmega103 compatibility mode, and should not
be used for 100% backward compatibility.
13.4.10 PORTD – Port D Data Register
Bit 76543210
0x12 (0x32)
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
PORTD7 PORTD6 PORTD5 PORTD4 PORTD3 PORTD2 PORTD1 PORTD0 PORTD
13.4.11 DDRD – Port D Data Direction Register
Bit 76543210
0x11 (0x31) DDD7 DDD6 DDD5 DDD4 DDD3 DDD2 DDD1 DDD0 DDRD
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
13.4.12 PIND – Port D Input Pins Address
Bit 76543210
0x10 (0x30) PIND7 PIND6 PIND5 PIND4 PIND3 PIND2 PIND1 PIND0 PIND
Read/WriteRRRRRRRR
Initial Value N/A N/A N/A N/A N/A N/A N/A N/A
ATmega64A
13.4.13 PORTE – Port E Data Register
Bit 76543210
0x03 (0x23)
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
PORTE7 PORTE6 PORTE5 PORTE4 PORTE3 PORTE2 PORTE1 PORTE0 PORTE
13.4.14 DDRE – Port E Data Direction Register
Bit 76543210
0x02 (0x22) DDE7 DDE6 DDE5 DDE4 DDE3 DDE2 DDE1 DDE0 DDRE
Read/WriteR/WR/WR/WR/WR/WR/WR/WR/W
Initial Value 0 0 0 0 0 0 0 0
13.4.15 PINE – Port E Input Pins Address
Bit 76543210
0x01 (0x21) PINE7 PINE6 PINE5 PINE4 PINE3 PINE2 PINE1 PINE0 PINF
Read/WriteRRRRRRRR
Initial Value N/A N/A N/A N/A N/A N/A N/A N/A
13.4.16 PORTF – Port F Data Register
Bit 76543210
(0x62)
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
PORTF7 PORTF6 PORTF5 PORTF4 PORTF3 PORTF2 PORTF1 PORTF0 PORTF
13.4.17 DDRF – Port F Data Direction Register
Bit 76543210
(0x61) DDF7 DDF6 DDF5 DDF4 DDF3 DDF2 DDF1 DDF0 DDRF
Read/Write R/W R/W R/W R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
8160C–AVR–07/09
90
Page 91
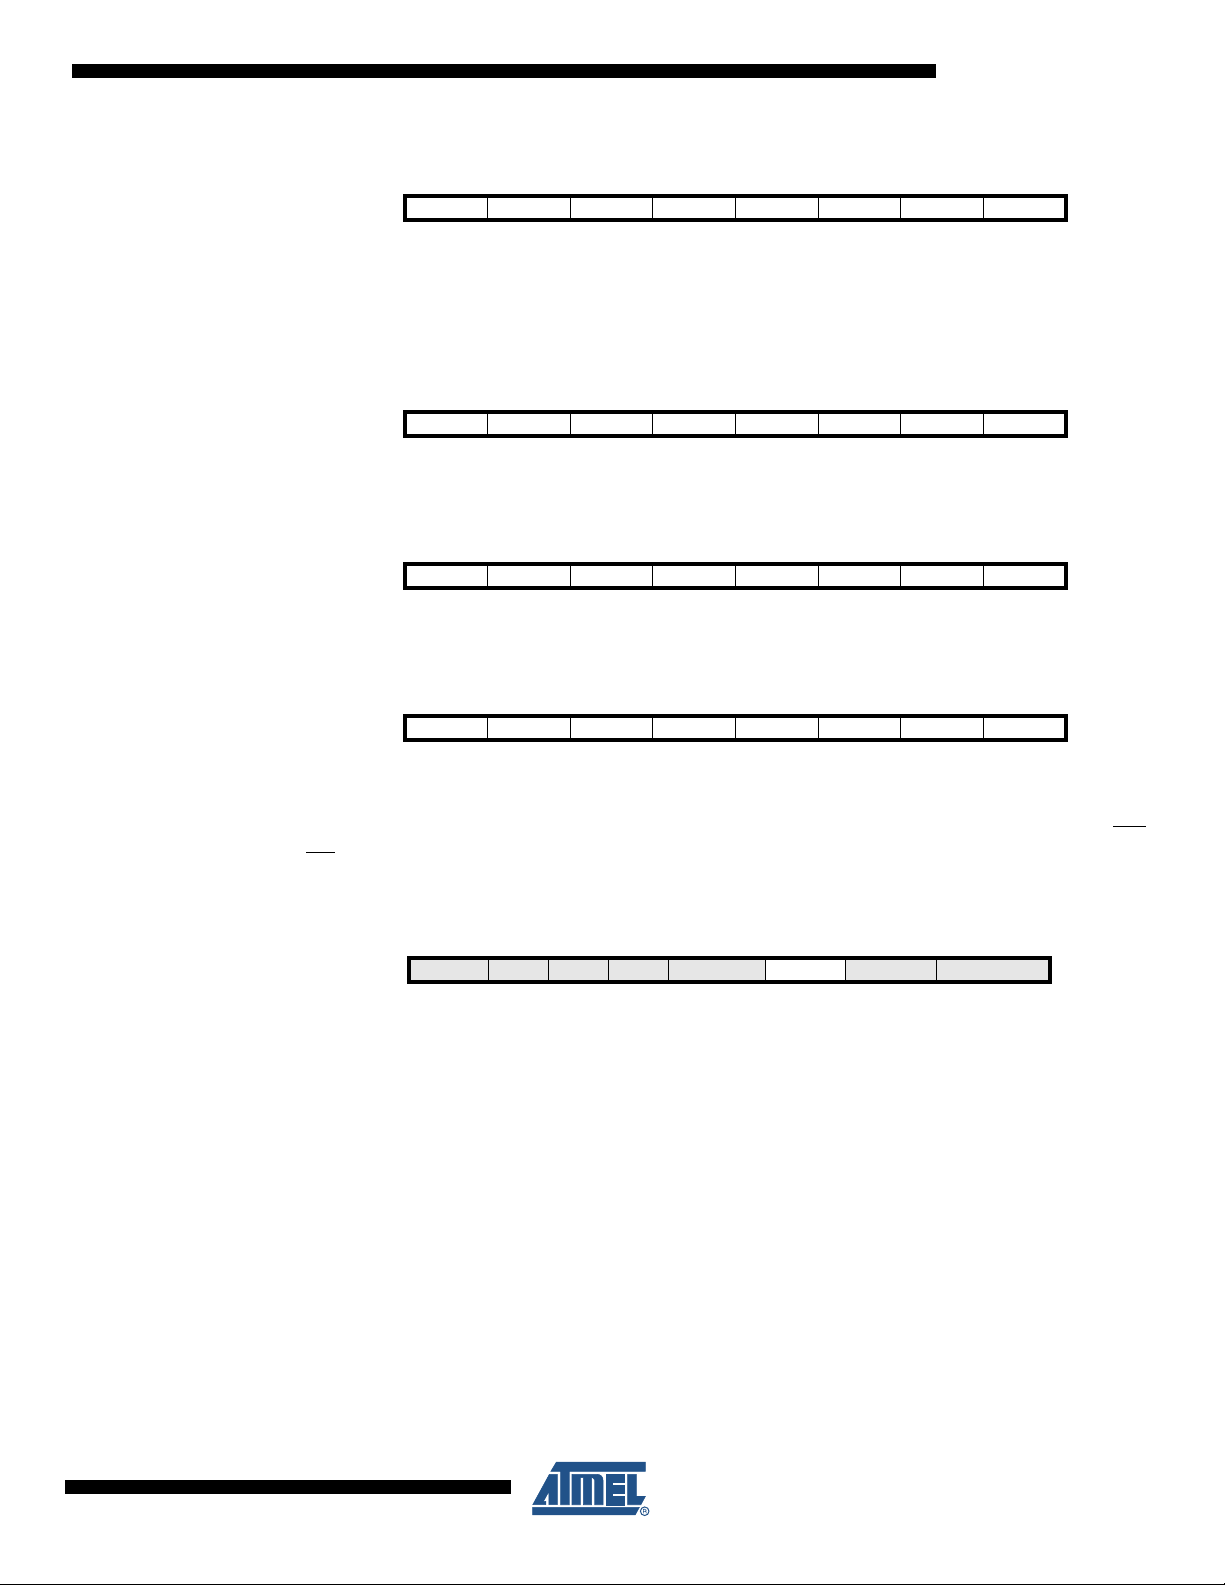
13.4.18 PINF – Port F Input Pins Address
Bit 76543210
0x00 (0x20) PINF7 PINF6 PINF5 PINF4 PINF3 PINF2 PINF1 PINF0 PINF
Read/WriteRRRRRRRR
Initial Value N/A N/A N/A N/A N/A N/A N/A N/A
Note that PORTF and DDRF Registers are not available in ATmega103 compatibility mode
where Port F serves as digital input only.
13.4.19 PORTG – Port G Data Register
Bit 76543210
(0x65)
Read/Write R R R R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
– – – PORTG4 PORTG3 PORTG2 PORTG1 PORTG0 PORTG
13.4.20 DDRG – Port G Data Direction Register
Bit 76543210
(0x64) – – – DDG4 DDG3 DDG2 DDG1 DDG0 DDRG
Read/Write R R R R/W R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
ATmega64A
13.4.21 PING – Port G Input Pins Address
Bit 76543210
(0x63) – – – PING4 PING3 PING2 PING1 PING0 PING
Read/WriteRRRRRRRR
Initial Value 0 0 0 N/A N/A N/A N/A N/A
Note that PORTG, DDRG, and PING are not available in ATmega103 compatibility mode. In the
ATmega103 compatibility mode Port G serves its alternate functions only (TOSC1, TOSC2, WR
RD
and ALE).
13.4.22 SFIOR – Special Function IO Register
Bit 7 654 3 2 1 0
0x20 (0x40)
Read/Write R/W R R R R/W R/W R/W R/W
Initial Value 0 0 0 0 0 0 0 0
TSM – – – ACME PUD PSR0 PSR321 SFIOR
• Bit 2 – PUD: Pull-up disable
When this bit is written to one, the pull-ups in the I/O ports are disabled even if the DDxn and
PORTxn Registers are configured to enable the pull-ups ({DDxn, PORTxn} = 0b01). See “Con-
figuring the Pin” on page 69 for more details about this feature.
,
8160C–AVR–07/09
91
Page 92
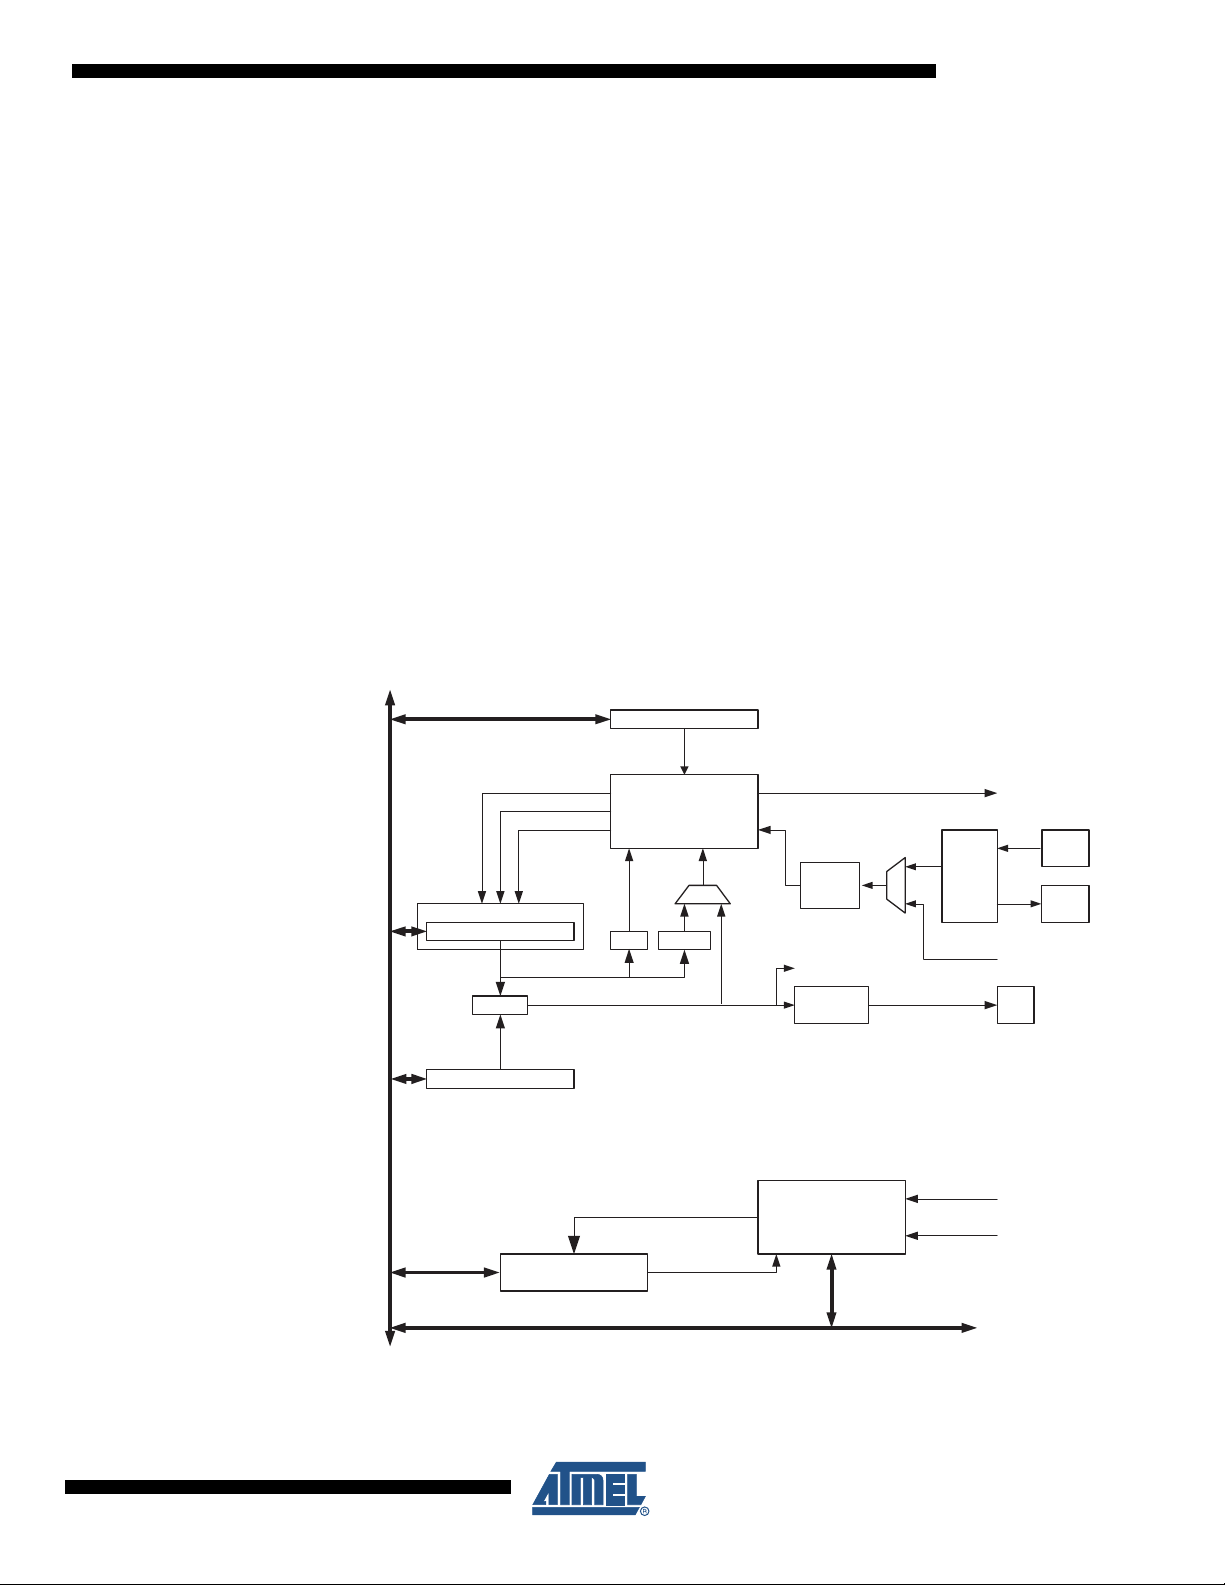
14. 8-bit Timer/Counter0 with PWM and Asynchronous Operation
Timer/Counter
DATA B U S
=
TCNTn
Wavefor m
Generation
OCn
= 0
Control Logic
=
0xFF
TOPBOTTOM
count
clear
direction
TOVn
(Int. Req.)
OCn
(Int. Req.)
Synchronization Unit
OCRn
TCCRn
ASSRn
Status Flags
clk
I/O
clk
ASY
Synchronized Status Flags
Asynchronous Mode
Select (ASn)
TOSC1
T/C
Oscillator
TOSC2
Prescaler
clk
Tn
clk
I/O
14.1 Features
• Single Channel Counter
• Clear Timer on Compare Match (Auto Reload)
• Glitch-free, Phase Correct Pulse Width Modulator (PWM)
• Frequency Generator
• 10-bit Clock Prescaler
• Overflow and Compare Match Interrupt Sources (TOV0 and OCF0)
• Allows Clocking from External 32 kHz Watch Crystal Independent of the I/O Clock
14.2 Overview
Timer/Counter0 is a general purpose, single-channel, 8-bit Timer/Counter module. A simplified
block diagram of the 8-bit Timer/Counter is shown in Figure 14-1. For the actual placement of
I/O pins, refer to “Pin Configuration” on page 2. CPU accessible I/O Registers, including I/O bits
and I/O pins, are shown in bold. The device-specific I/O Register and bit locations are listed in
the “Register Description” on page 106.
ATmega64A
Figure 14-1. 8-bit Timer/Counter Block Diagram.
8160C–AVR–07/09
Registers
92
Page 93
14.2.1 Definitions
ATmega64A
The Timer/Counter (TCNT0) and Output Compare Register (OCR0) are 8-bit registers. Interrupt
request (shorten as Int.Req.) signals are all visible in the Timer Interrupt Flag Register (TIFR).
All interrupts are individually masked with the Timer Interrupt Mask Register (TIMSK). TIFR and
TIMSK are not shown in the figure since these registers are shared by other timer units.
The Timer/Counter can be clocked internally, via the prescaler, or asynchronously clocked from
the TOSC1/2 pins, as detailed later in this section. The asynchronous operation is controlled by
the Asynchronous Status Register (ASSR). The Clock Select logic block controls which clock
source the Timer/Counter uses to increment (or decrement) its value. The Timer/Counter is inactive when no clock source is selected. The output from the Clock Select logic is referred to as the
timer clock (clk
The double buffered Output Compare Register (OCR0) is compared with the Timer/Counter
value at all times. The result of the compare can be used by the Waveform Generator to generate a PWM or variable frequency output on the Output Compare pin (OC0). See “Output
Compare Unit” on page 94. for details. The Compare Match event will also set the Compare Flag
(OCF0) which can be used to generate an Output Compare interrupt request.
Many register and bit references in this datasheet are written in general form. A lower case “n”
replaces the Timer/Counter number, in this case 0. However, when using the register or bit
defines in a program, the precise form must be used i.e. TCNT0 for accessing Timer/Counter0
counter value and so on.
T0
).
The definitions in Table 14-1 are also used extensively throughout this section.
Table 14-1. Definitions
BOTTOM The counter reaches the BOTTOM when it becomes zero (0x00).
MAX The counter reaches its MAXimum when it becomes 0xFF (decimal 255).
TOP The counter reaches the TOP when it becomes equal to the highest value in the
count sequence. The TOP value can be assigned to be the fixed value 0xFF
(MAX) or the value stored in the OCR0 Register. The assignment is dependent
on the mode of operation.
14.3 Timer/Counter Clock Sources
The Timer/Counter can be clocked by an internal synchronous or an external asynchronous
clock source. The clock source clk
bit in the ASSR Register is written to logic one, the clock source is taken from the Timer/Counter
Oscillator connected to TOSC1 and TOSC2. For details on asynchronous operation, see “ASSR
– Asynchronous Status Register” on page 108. For details on clock sources and prescaler, see
“Timer/Counter Prescaler” on page 105.
14.4 Counter Unit
The main part of the 8-bit Timer/Counter is the programmable bi-directional counter unit. Figure
14-2 shows a block diagram of the counter and its surrounding environment.
is by default equal to the MCU clock, clk
T0
. When the AS0
I/O
8160C–AVR–07/09
93
Page 94
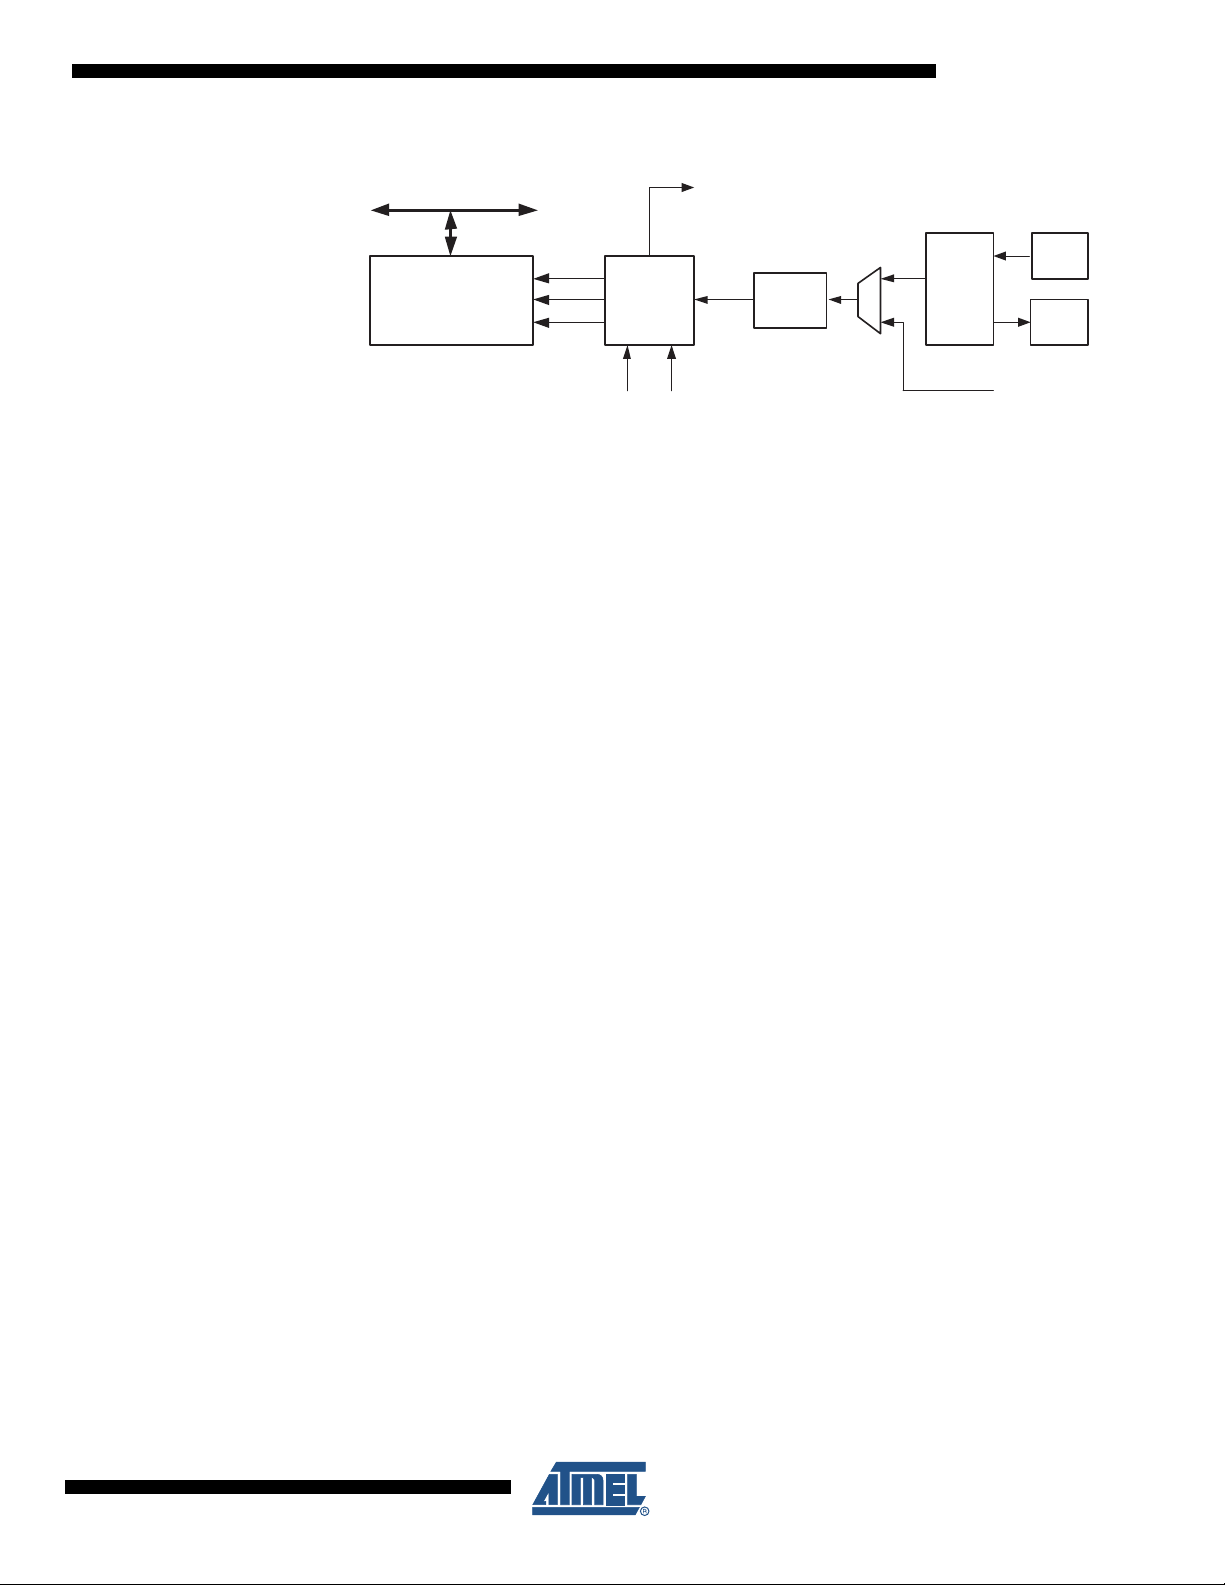
Figure 14-2. Counter Unit Block Diagram
DATA B US
TCNTn Control Logic
count
TOVn
(Int.Req.)
topbottom
direction
clear
TOSC1
T/C
Oscillator
TOSC2
Prescaler
clk
I/O
clk
Tn
Signal description (internal signals):
count Increment or decrement TCNT0 by 1.
direction Selects between increment and decrement.
clear Clear TCNT0 (set all bits to zero).
ATmega64A
Depending on the mode of operation used, the counter is cleared, incremented, or decremented
at each timer clock (clk
selected by the Clock Select bits (CS02:0). When no clock source is selected (CS02:0 = 0) the
timer is stopped. However, the TCNT0 value can be accessed by the CPU, regardless of
whether clk
count operations.
The counting sequence is determined by the setting of the WGM01 and WGM00 bits located in
the Timer/Counter Control Register (TCCR0). There are close connections between how the
counter behaves (counts) and how waveforms are generated on the Output Compare output
OC0. For more details about advanced counting sequences and waveform generation, see
“Modes of Operation” on page 97.
The Timer/Counter Overflow Flag (TOV0) is set according to the mode of operation selected by
the WGM01:0 bits.
14.5 Output Compare Unit
The 8-bit comparator continuously compares TCNT0 with the Output Compare Register
(OCR0). Whenever TCNT0 equals OCR0, the comparator signals a match. A match will set the
Output Compare Flag (OCF0) at the next timer clock cycle. If enabled (OCIE0 = 1), the Output
Compare Flag generates an Output Compare interrupt. The OCF0 flag is automatically cleared
when the interrupt is executed. Alternatively, the OCF0 flag can be cleared by software by writing a logical one to its I/O bit location. The Waveform Generator uses the match signal to
generate an output according to operating mode set by the WGM01:0 bits and Compare Output
mode (COM01:0) bits. The max and bottom signals are used by the Waveform Generator for
handling the special cases of the extreme values in some modes of operation (“Modes of Oper-
ation” on page 97). Figure 14-3 shows a block diagram of the Output Compare unit.
clk
T0
Timer/Counter clock.
top Signalizes that TCNT0 has reached maximum value.
bottom Signalizes that TCNT0 has reached minimum value (zero).
). clkT0 can be generated from an external or internal clock source,
T0
is present or not. A CPU write overrides (has priority over) all counter clear or
T0
TOV0 can be used for generating a CPU interrupt.
8160C–AVR–07/09
94
Page 95
ATmega64A
OCFn (Int.Req.)
= (8-bit Comparator )
OCRn
OCxy
DATA B US
TCNTn
WGMn1:0
Waveform Generator
top
FOCn
COMn1:0
bottom
Figure 14-3. Output Compare Unit, Block Diagram
The OCR0 Register is double buffered when using any of the Pulse Width Modulation (PWM)
modes. For the normal and Clear Timer on Compare (CTC) modes of operation, the double buffering is disabled. The double buffering synchronizes the update of the OCR0 Compare Register
to either top or bottom of the counting sequence. The synchronization prevents the occurrence
of odd-length, non-symmetrical PWM pulses, thereby making the output glitch-free.
The OCR0 Register access may seem complex, but this is not case. When the double buffering
is enabled, the CPU has access to the OCR0 Buffer Register, and if double buffering is disabled
the CPU will access the OCR0 directly.
14.5.1 Force Output Compare
In non-PWM waveform generation modes, the match output of the comparator can be forced by
writing a one to the Force Output Compare (FOC0) bit. Forcing Compare Match will not set the
OCF0 flag or reload/clear the timer, but the OC0 pin will be updated as if a real Compare Match
had occurred (the COM01:0 bits settings define whether the OC0 pin is set, cleared or toggled).
14.5.2 Compare Match Blocking by TCNT0 Write
All CPU write operations to the TCNT0 Register will block any Compare Match that occurs in the
next timer clock cycle, even when the timer is stopped. This feature allows OCR0 to be initialized
to the same value as TCNT0 without triggering an interrupt when the Timer/Counter clock is
enabled.
14.5.3 Using the Output Compare Unit
Since writing TCNT0 in any mode of operation will block all Compare Matches for one timer
clock cycle, there are risks involved when changing TCNT0 when using the Output Compare
channel, independently of whether the Timer/Counter is running or not. If the value written to
TCNT0 equals the OCR0 value, the Compare Match will be missed, resulting in incorrect waveform generation. Similarly, do not write the TCNT0 value equal to BOTTOM when the counter is
downcounting.
8160C–AVR–07/09
The setup of the OC0 should be performed before setting the Data Direction Register for the port
pin to output. The easiest way of setting the OC0 value is to use the Force Output Compare
95
Page 96
(FOC0) strobe bit in Normal mode. The OC0 Register keeps its value even when changing
PORT
DDR
DQ
DQ
OCn
Pin
OCn
DQ
Waveform
Generator
COMn1
COMn0
0
1
DATA BU S
FOCn
clk
I/O
between waveform generation modes.
Be aware that the COM01:0 bits are not double buffered together with the compare value.
Changing the COM01:0 bits will take effect immediately.
14.6 Compare Match Output Unit
The Compare Output mode (COM01:0) bits have two functions. The Waveform Generator uses
the COM01:0 bits for defining the Output Compare (OC0) state at the next Compare Match.
Also, the COM01:0 bits control the OC0 pin output source. Figure 14-4 shows a simplified schematic of the logic affected by the COM01:0 bit setting. The I/O Registers, I/O bits, and I/O pins in
the figure are shown in bold. Only the parts of the general I/O port control registers (DDR and
PORT) that are affected by the COM01:0 bits are shown. When referring to the OC0 state, the
reference is for the internal OC0 Register, not the OC0 pin.
Figure 14-4. Compare Match Output Unit, Schematic
ATmega64A
8160C–AVR–07/09
The general I/O port function is overridden by the Output Compare (OC0) from the Waveform
Generator if either of the COM01:0 bits are set. However, the OC0 pin direction (input or output)
is still controlled by the Data Direction Register (DDR) for the port pin. The Data Direction Register bit for the OC0 pin (DDR_OC0) must be set as output before the OC0 value is visible on the
pin. The port override function is independent of the Waveform Generation mode.
The design of the Output Compare pin logic allows initialization of the OC0 state before the output is enabled. Note that some COM01:0 bit settings are reserved for certain modes of
operation. See “Register Description” on page 106.
96
Page 97
14.6.1 Compare Output Mode and Waveform Generation
The Waveform Generator uses the COM01:0 bits differently in Normal, CTC, and PWM modes.
For all modes, setting the COM01:0 = 0 tells the Waveform Generator that no action on the OC0
Register is to be performed on the next Compare Match. For compare output actions in the nonPWM modes refer to Table 14-3 on page 107. For fast PWM mode, refer to Table 14-4 on page
107, and for phase correct PWM refer to Table 14-5 on page 107.
A change of the COM01:0 bits state will have effect at the first Compare Match after the bits are
written. For non-PWM modes, the action can be forced to have immediate effect by using the
FOC0 strobe bits.
14.7 Modes of Operation
The mode of operation, i.e., the behavior of the Timer/Counter and the Output Compare pins, is
defined by the combination of the Waveform Generation mode (WGM01:0) and Compare Output
mode (COM01:0) bits. The Compare Output mode bits do not affect the counting sequence,
while the Waveform Generation mode bits do. The COM01:0 bits control whether the PWM output generated should be inverted or not (inverted or non-inverted PWM). For non-PWM modes
the COM01:0 bits control whether the output should be set, cleared, or toggled at a Compare
Match (See “Compare Match Output Unit” on page 96.).
For detailed timing information refer to “Timer/Counter Timing Diagrams” on page 101.
ATmega64A
14.7.1 Normal Mode
The simplest mode of operation is the Normal mode (WGM01:0 = 0). In this mode the counting
direction is always up (incrementing), and no counter clear is performed. The counter simply
overruns when it passes its maximum 8-bit value (TOP = 0xFF) and then restarts from the bottom (0x00). In normal operation the Timer/Counter Overflow Flag (TOV0) will be set in the same
timer clock cycle as the TCNT0 becomes zero. The TOV0 flag in this case behaves like a ninth
bit, except that it is only set, not cleared. However, combined with the timer overflow interrupt
that automatically clears the TOV0 flag, the timer resolution can be increased by software. There
are no special cases to consider in the Normal mode, a new counter value can be written
anytime.
The Output Compare unit can be used to generate interrupts at some given time. Using the Output Compare to generate waveforms in Normal mode is not recommended, since this will
occupy too much of the CPU time.
14.7.2 Clear Timer on Compare Match (CTC) Mode
In Clear Timer on Compare or CTC mode (WGM01:0 = 2), the OCR0 Register is used to manipulate the counter resolution. In CTC mode the counter is cleared to zero when the counter value
(TCNT0) matches the OCR0. The OCR0 defines the top value for the counter, hence also its
resolution. This mode allows greater control of the Compare Match output frequency. It also simplifies the operation of counting external events.
The timing diagram for the CTC mode is shown in Figure 14-5. The counter value (TCNT0)
increases until a Compare Match occurs between TCNT0 and OCR0, and then counter (TCNT0)
is cleared.
8160C–AVR–07/09
97
Page 98
ATmega64A
TCNTn
OCn
(Toggle)
OCn Interrupt Flag Set
1 4
Period
2 3
(COMn1:0 = 1)
f
OCn
f
clk_I/O
2 N 1 OCRn+()⋅⋅
-----------------------------------------------=
Figure 14-5. CTC Mode, Timing Diagram
An interrupt can be generated each time the counter value reaches the TOP value by using the
OCF0 flag. If the interrupt is enabled, the interrupt handler routine can be used for updating the
TOP value. However, changing the TOP to a value close to BOTTOM when the counter is running with none or a low prescaler value must be done with care since the CTC mode does not
have the double buffering feature. If the new value written to OCR0 is lower than the current
value of TCNT0, the counter will miss the Compare Match. The counter will then have to count to
its maximum value (0xFF) and wrap around starting at 0x00 before the Compare Match can
occur.
14.7.3 Fast PWM Mode
For generating a waveform output in CTC mode, the OC0 output can be set to toggle its logical
level on each Compare Match by setting the Compare Output mode bits to toggle mode
(COM01:0 = 1). The OC0 value will not be visible on the port pin unless the data direction for the
pin is set to output. The waveform generated will have a maximum frequency of f
OC0
= f
clk_I/O
/2
when OCR0 is set to zero (0x00). The waveform frequency is defined by the following equation:
The N variable represents the prescale factor (1, 8, 32, 64, 128, 256, or 1024).
As for the Normal mode of operation, the TOV0 flag is set in the same timer clock cycle that the
counter counts from MAX to 0x00.
The fast Pulse Width Modulation or fast PWM mode (WGM01:0 = 3) provides a high frequency
PWM waveform generation option. The fast PWM differs from the other PWM option by its single-slope operation. The counter counts from BOTTOM to MAX then restarts from BOTTOM. In
non-inverting Compare Output mode, the Output Compare (OC0) is cleared on the Compare
Match between TCNT0 and OCR0, and set at BOTTOM. In inverting Compare Output mode, the
output is set on Compare Match and cleared at BOTTOM. Due to the single-slope operation, the
operating frequency of the fast PWM mode can be twice as high as the phase correct PWM
mode that uses dual-slope operation. This high frequency makes the fast PWM mode well suited
for power regulation, rectification, and DAC applications. High frequency allows physically small
sized external components (coils, capacitors), and therefore reduces total system cost.
8160C–AVR–07/09
In fast PWM mode, the counter is incremented until the counter value matches the MAX value.
The counter is then cleared at the following timer clock cycle. The timing diagram for the fast
PWM mode is shown in Figure 14-6. The TCNT0 value is in the timing diagram shown as a his-
98
Page 99
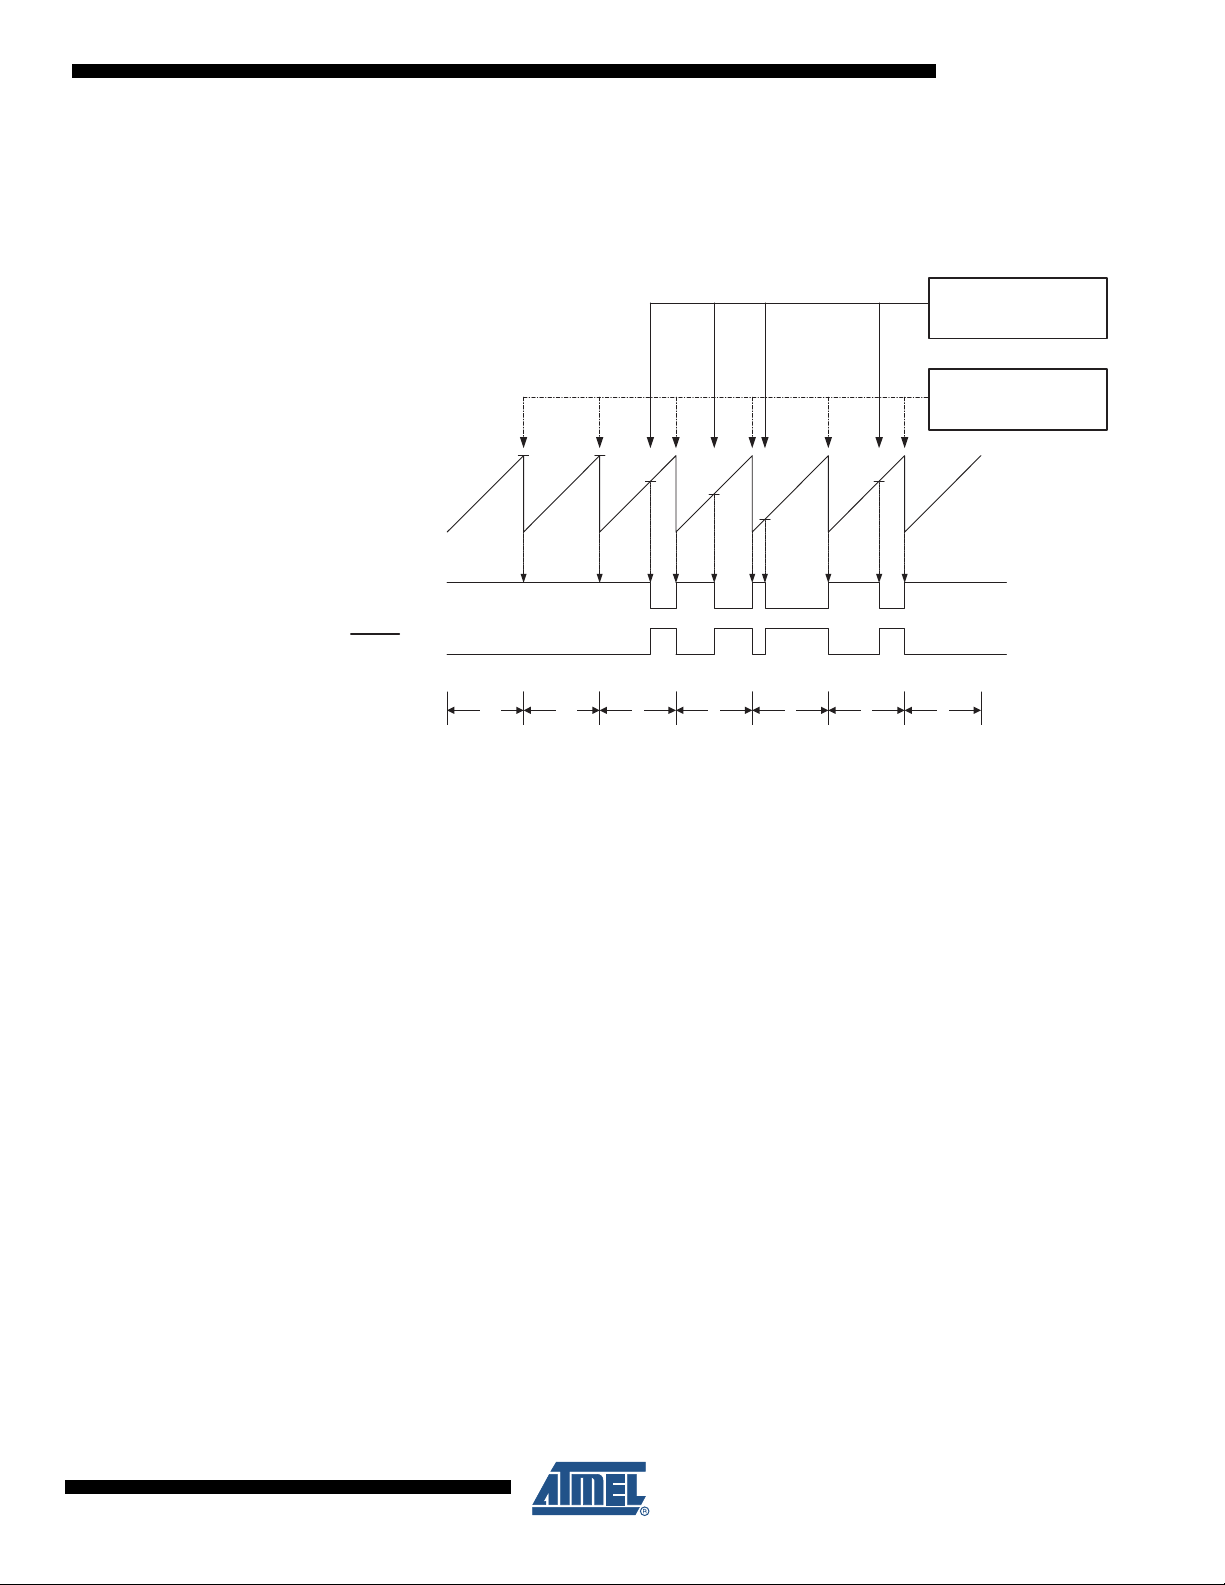
ATmega64A
TCNTn
OCRn Update and
TOVn Interrupt Flag Set
1
Period
2 3
OCn
OCn
(COMn1:0 = 2)
(COMn1:0 = 3)
OCRn Interrupt Flag Set
4 5 6 7
f
OCnPWM
f
clk_I/O
N 256⋅
------------------=
togram for illustrating the single-slope operation. The diagram includes non-inverted and
inverted PWM outputs. The small horizontal line marks on the TCNT0 slopes represent Compare Matches between OCR0 and TCNT0.
Figure 14-6. Fast PWM Mode, Timing Diagram
The Timer/Counter Overflow Flag (TOV0) is set each time the counter reaches MAX. If the interrupt is enabled, the interrupt handler routine can be used for updating the compare value.
In fast PWM mode, the compare unit allows generation of PWM waveforms on the OC0 pin. Setting the COM01:0 bits to two will produce a non-inverted PWM and an inverted PWM output can
be generated by setting the COM01:0 to three (See Table 14-4 on page 107). The actual OC0
value will only be visible on the port pin if the data direction for the port pin is set as output. The
PWM waveform is generated by setting (or clearing) the OC0 Register at the Compare Match
between OCR0 and TCNT0, and clearing (or setting) the OC0 Register at the timer clock cycle
the counter is cleared (changes from MAX to BOTTOM).
The PWM frequency for the output can be calculated by the following equation:
The N variable represents the prescale factor (1, 8, 32, 64, 128, 256, or 1024).
The extreme values for the OCR0 Register represent special cases when generating a PWM
waveform output in the fast PWM mode. If the OCR0 is set equal to BOTTOM, the output will be
a narrow spike for each MAX+1 timer clock cycle. Setting the OCR0 equal to MAX will result in a
constantly high or low output (depending on the polarity of the output set by the COM01:0 bits.)
A frequency (with 50% duty cycle) waveform output in fast PWM mode can be achieved by setting OC0 to toggle its logical level on each Compare Match (COM01:0 = 1). The waveform
generated will have a maximum frequency of f
oc0
= f
/2 when OCR0 is set to zero. This fea-
clk_I/O
ture is similar to the OC0 toggle in CTC mode, except the double buffer feature of the Output
Compare unit is enabled in the fast PWM mode.
8160C–AVR–07/09
99
Page 100
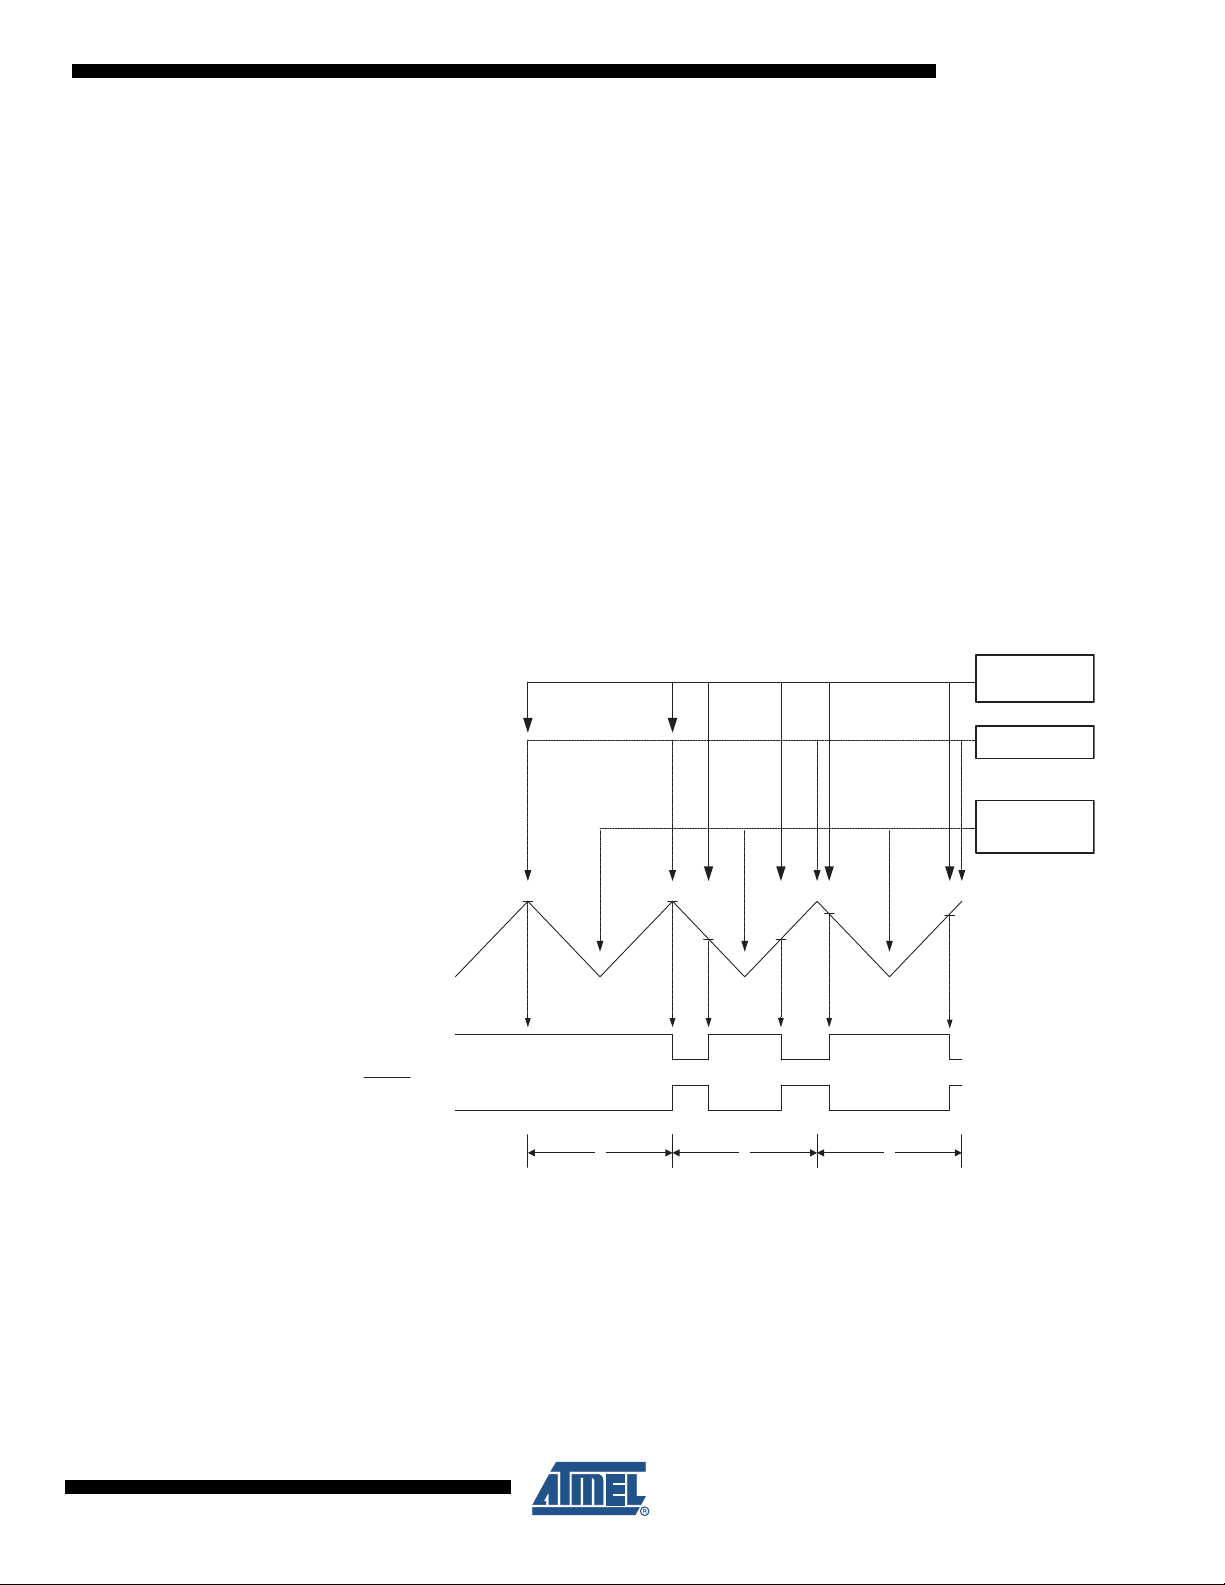
14.7.4 Phase Correct PWM Mode
TOVn Interrupt
Flag Set
OCn Interrupt
Flag Set
1 2 3
TCNTn
Period
OCn
OCn
(COMn1:0 = 2)
(COMn1:0 = 3)
OCRn Update
The phase correct PWM mode (WGM01:0 = 1) provides a high resolution phase correct PWM
waveform generation option. The phase correct PWM mode is based on a dual-slope operation.
The counter counts repeatedly from BOTTOM to MAX and then from MAX to BOTTOM. In noninverting Compare Output mode, the Output Compare (OC0) is cleared on the Compare Match
between TCNT0 and OCR0 while upcounting, and set on the Compare Match while downcounting. In inverting Output Compare mode, the operation is inverted. The dual-slope operation has
lower maximum operation frequency than single slope operation. However, due to the symmetric feature of the dual-slope PWM modes, these modes are preferred for motor control
applications.
The PWM resolution for the phase correct PWM mode is fixed to eight bits. In phase correct
PWM mode the counter is incremented until the counter value matches MAX. When the counter
reaches MAX, it changes the count direction. The TCNT0 value will be equal to MAX for one
timer clock cycle. The timing diagram for the phase correct PWM mode is shown on Figure 14-7.
The TCNT0 value is in the timing diagram shown as a histogram for illustrating the dual-slope
operation. The diagram includes non-inverted and inverted PWM outputs. The small horizontal
line marks on the TCNT0 slopes represent Compare Matches between OCR0 and TCNT0.
Figure 14-7. Phase Correct PWM Mode, Timing Diagram
ATmega64A
8160C–AVR–07/09
The Timer/Counter Overflow Flag (TOV0) is set each time the counter reaches BOTTOM. The
interrupt flag can be used to generate an interrupt each time the counter reaches the BOTTOM
value.
In phase correct PWM mode, the compare unit allows generation of PWM waveforms on the
OC0 pin. Setting the COM01:0 bits to two will produce a non-inverted PWM. An inverted PWM
output can be generated by setting the COM01:0 to three (See Table 14-5 on page 107). The
actual OC0 value will only be visible on the port pin if the data direction for the port pin is set as
output. The PWM waveform is generated by clearing (or setting) the OC0 Register at the Com-
100
 Loading...