

Page 1
4022-D018396
07
4022-D018396 Revision: 07
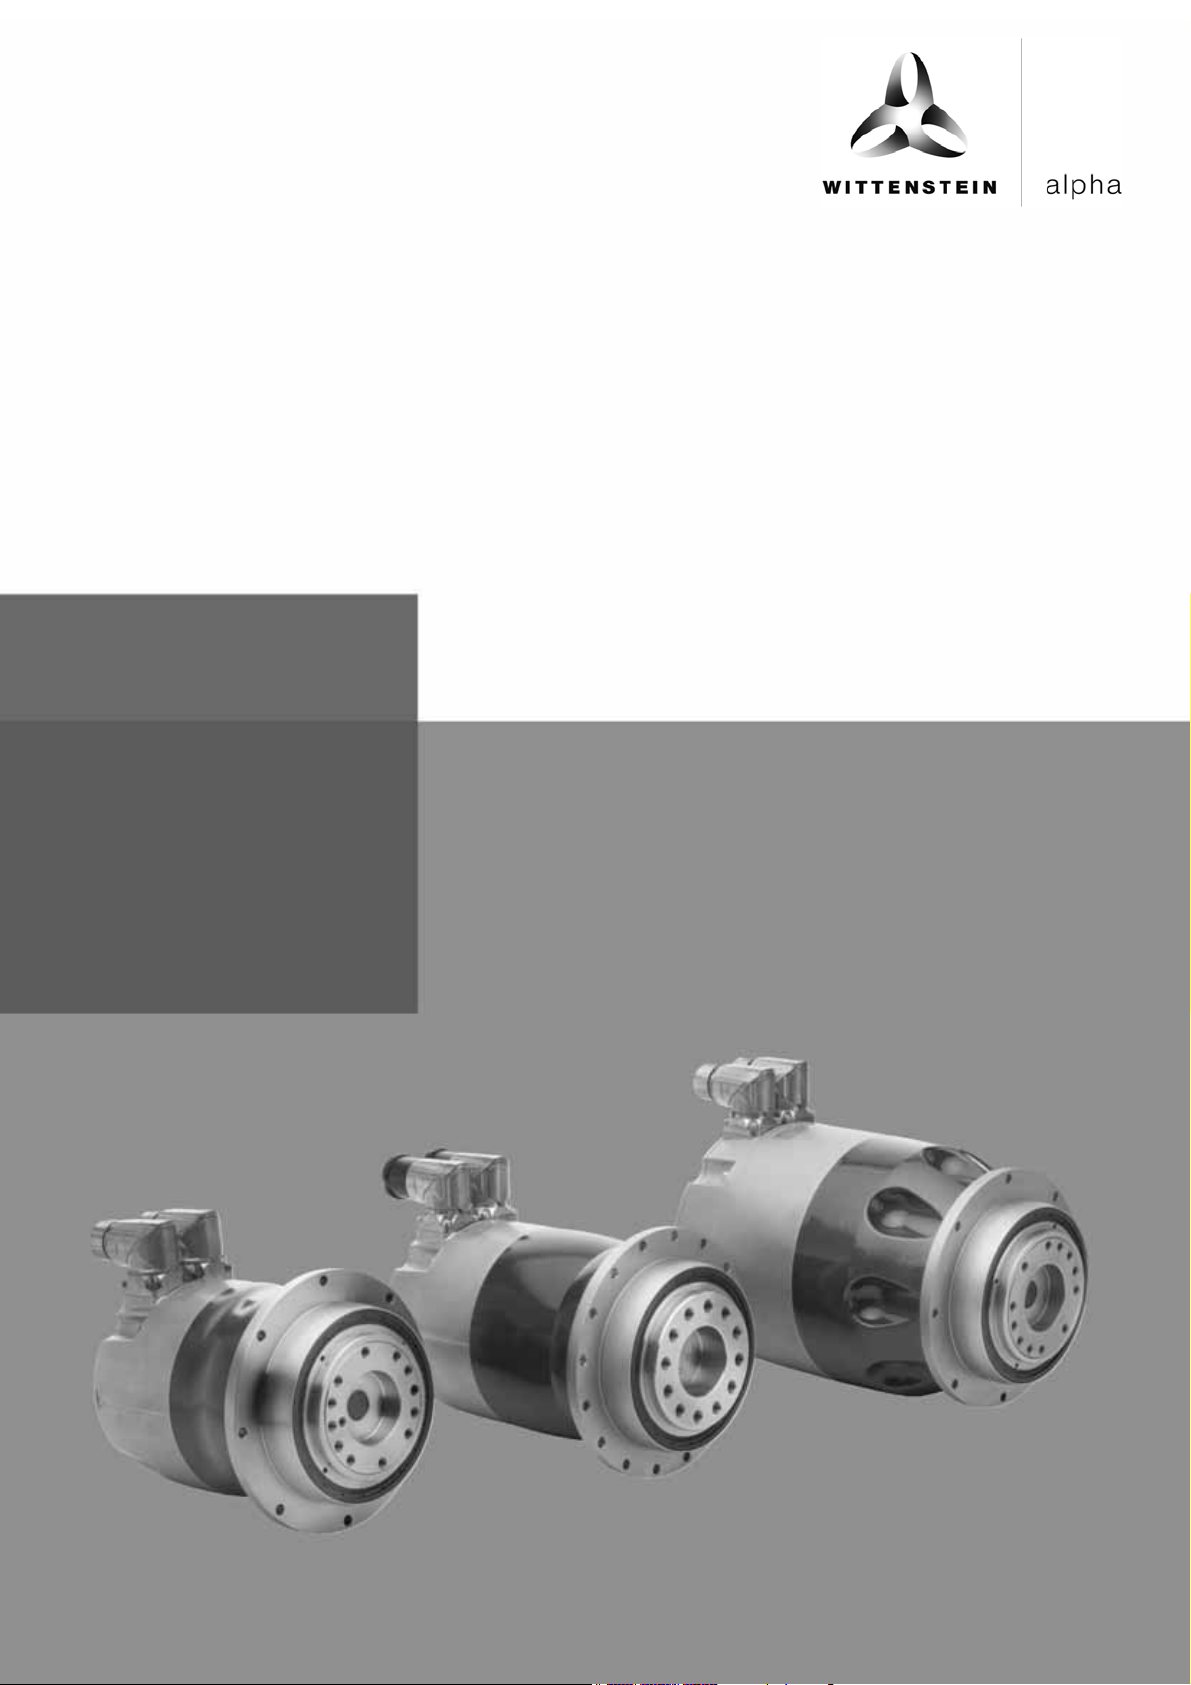
Operating Manual
TPM
+
dynamic / high torque / power
Page 2
Revision history
Service
In case you have technical questions,
please contact:
WITTENSTEIN alpha GmbH
Customer Service
Walter-Wittenstein-Straße 1
D-97999 Igersheim
Tel.: +49 7931 493-12900
Fax: +49 7931 493-10903
E-mail: [email protected]
© WITTENSTEIN alpha GmbH 2017
This documentation is copyright protected.
reserves all the rights to photo-mechanical reproduction, copying, and the distribution
by special processes (such as computers, file media, data networks), even in parts.
Subject to technical and content changes without notice
.
Revision Date Comment Chapter
01 16.12.09 New version All
02 13.04.10 Technical data 9.4
03 25.07.11 high torque All
04 03.02.17 W-alpha All
05 27.02.17 Service-Tel All
06 21.06.17 Speedtec counter plug 5.4
TPM
+
07 03.08.17 Security,
All
Technical data
4022-D018396 Revision: 07
Page 3
+
TPM
Contents
1 About this manual ................................................................................................5
1.1 Signal words ........................................................................................................5
1.2 Safety symbols.....................................................................................................5
1.3 Design of the safety instructions..........................................................................6
1.4 Information symbols.............................................................................................6
2 Safety.....................................................................................................................7
2.1 EU Low Voltage Directive ....................................................................................7
2.2 Dangers ...............................................................................................................7
2.3 Personnel.............................................................................................................7
2.4 Intended use........................................................................................................7
2.5 Reasonably foreseeable misuse....................................................................... ...8
2.6 Guarantee and liability.........................................................................................8
2.7 General safety instructions ..................................................................................8
2.8 Safety signs .......................................................................................................10
3 Description of the servo actuator .....................................................................11
3.1 Identification plate..............................................................................................11
3.2 Ordering code....................................................................................................12
3.3 Performance statistics........................................................................................12
3.4 Weight................................................................................................................12
3.4.1 Weight TPM
3.4.2 Weight TPM
3.4.3 Weight TPM
+
dynamic...................................................................................12
+
high torque..............................................................................13
+
power......................................................................................13
4 Transport and storage .......................................................................................14
4.1 Scope of delivery ...............................................................................................14
4.2 Packaging..........................................................................................................14
4.3 Transport............................................................................................................14
4.4 Storage ..............................................................................................................14
5 Assembly ............................................................................................................15
5.1 Preparations.......................................................................................................15
5.2 Mounting the servo actuator onto a machine....................................................15
5.3 Components mounted on the output side..........................................................16
5.4 Installing electrical connections .........................................................................16
6 Startup and operation ........................................................................................18
6.1 Safety instructions and operating conditions .....................................................18
6.2 Data for the electrical startup.............................................................................18
7 Maintenance and disposal.................................................................................20
7.1 Maintenance work..............................................................................................20
7.1.1 Refreshment of holding brake.......................................................................20
7.1.2 Visual inspection ...........................................................................................21
7.1.3 Checking the tightening torques....................................................................21
7.1.4 Cleaning........................................................................................................22
7.2 Startup after maintenance work.........................................................................22
7.3 Maintenance schedule.......................................................................................22
7.4 Information on the lubricant used.......................................................................22
7.5 Disposal .............................................................................................................23
8 Malfunctions .......................................................................................................24
Revision: 07 4022-D018396 en-3
Page 4
9 Appendix ............................................................................................................ 26
9.1 Specifications on mounting onto a machine...................................................... 26
9.1.1 Specifications for the TPM
9.1.2 Specifications for the TPM
+
dynamic/TPM+ power version.......................... 26
+
high torque version .......................................... 26
9.2 Specifications on mounting on the gear output side..........................................26
9.2.1 Thread in output flange, TPM
9.2.2 Thread in output flange, TPM
9.2.3 Thread in output flange, TPM
+
dynamic.......................................................26
+
high torque .................................................. 27
+
power........................................................... 27
9.3 Tightening torques for common thread sizes in general
mechanical engineering ....................................................................................27
9.4 Technical specifications ....................................................................................27
9.4.1 Moments of inertia TPM
9.4.2 Moments of inertia TPM
9.4.3 Moments of inertia TPM
9.4.4 Motor data, TPM
9.4.5 Motor data, TPM
9.4.6 Motor data, TPM
9.4.7 Motor data, TPM
9.4.8 Motor data, TPM
9.4.9 Motor data, TPM
9.4.10Motor data, TPM
9.4.11Motor data, TPM
9.4.12Motor data, TPM
+
+
+
+
+
+
+
+
+
+
dynamic ...............................................................27
+
high torque........................................................... 28
+
power...................................................................29
dynamic 320V, i = 16 – 31...............................................30
dynamic 320V, i = 61 – 91...............................................31
high torque 320V.............................................................31
power 320V.....................................................................32
dynamic 560V, i = 16 – 31...............................................33
dynamic 560V, i = 61 – 91...............................................34
high torque 560V............................................................34
power 560V, i = 4 – 35 ................................................... 35
power 560V, i = 40 – 100 ............................................... 36
9.4.13Technical specifications, Resolver...............................................................37
9.4.14Technical specifications Stegmann Hiperface absolute encoder.................38
9.4.15Technical specifications Stegmann Hiperface absolute encoder,
Rockwell option............................................................................................. 38
9.4.16Technical specifications Heidenhain EnDat absolute encoder.................... 39
9.4.17Technical specifications Heidenhain Incremental........................................ 39
9.4.18Technical specifications TTL Encoder incremental...................................... 40
9.4.19Technical specifications temperature sensors KTY and NTC...................... 40
9.4.20Technical specifications temperature sensor PTC.......................................41
9.4.21Technical specifications brake TPM
9.4.22Technical specifications brake TPM
9.4.23Technical specifications brake TPM
+
dynamic ............................................ 41
+
high torque........................................ 42
+
power................................................ 42
9.4.24Pin assignment 1 .........................................................................................42
9.4.25Pin assignment 4 .........................................................................................46
9.4.26Pin assignment 5 TPM
+
dynamic................................................................. 48
9.4.27Pin assignment 6 .........................................................................................49
9.4.28Cable setup / Cable cross-section............................................................... 50
TPM
+
en-4 4022-D018396 Revision: 07
Page 5
+
TPM
1 About this manual
These instructions contain information necessary for the safe operation of the TPM+ dynamic/
TPM+ high torque/ TPM+ power servo actuator, referred to as the servo actuator in the following.
If this manual is supplied with an amendment (e.g. for special a pplications), then the information in
the amendment is valid. Contradictory specifications in this manual thereby become obsolete.
In case of questions on the special applications, please contact WITTENSTEIN alpha GmbH.
The operator must ensure that these instructions are read through by all persons assigned to install,
operate, or maintain the servo actuator, and that they fully comprehend them.
Store these instructions within reach of the servo actuator.
These safety instructions should be shared with colleagues working in the vicinity of the device
to ensure individual safety.
The original instructions were prepared in German; all other language versions are translations of
these instructions.
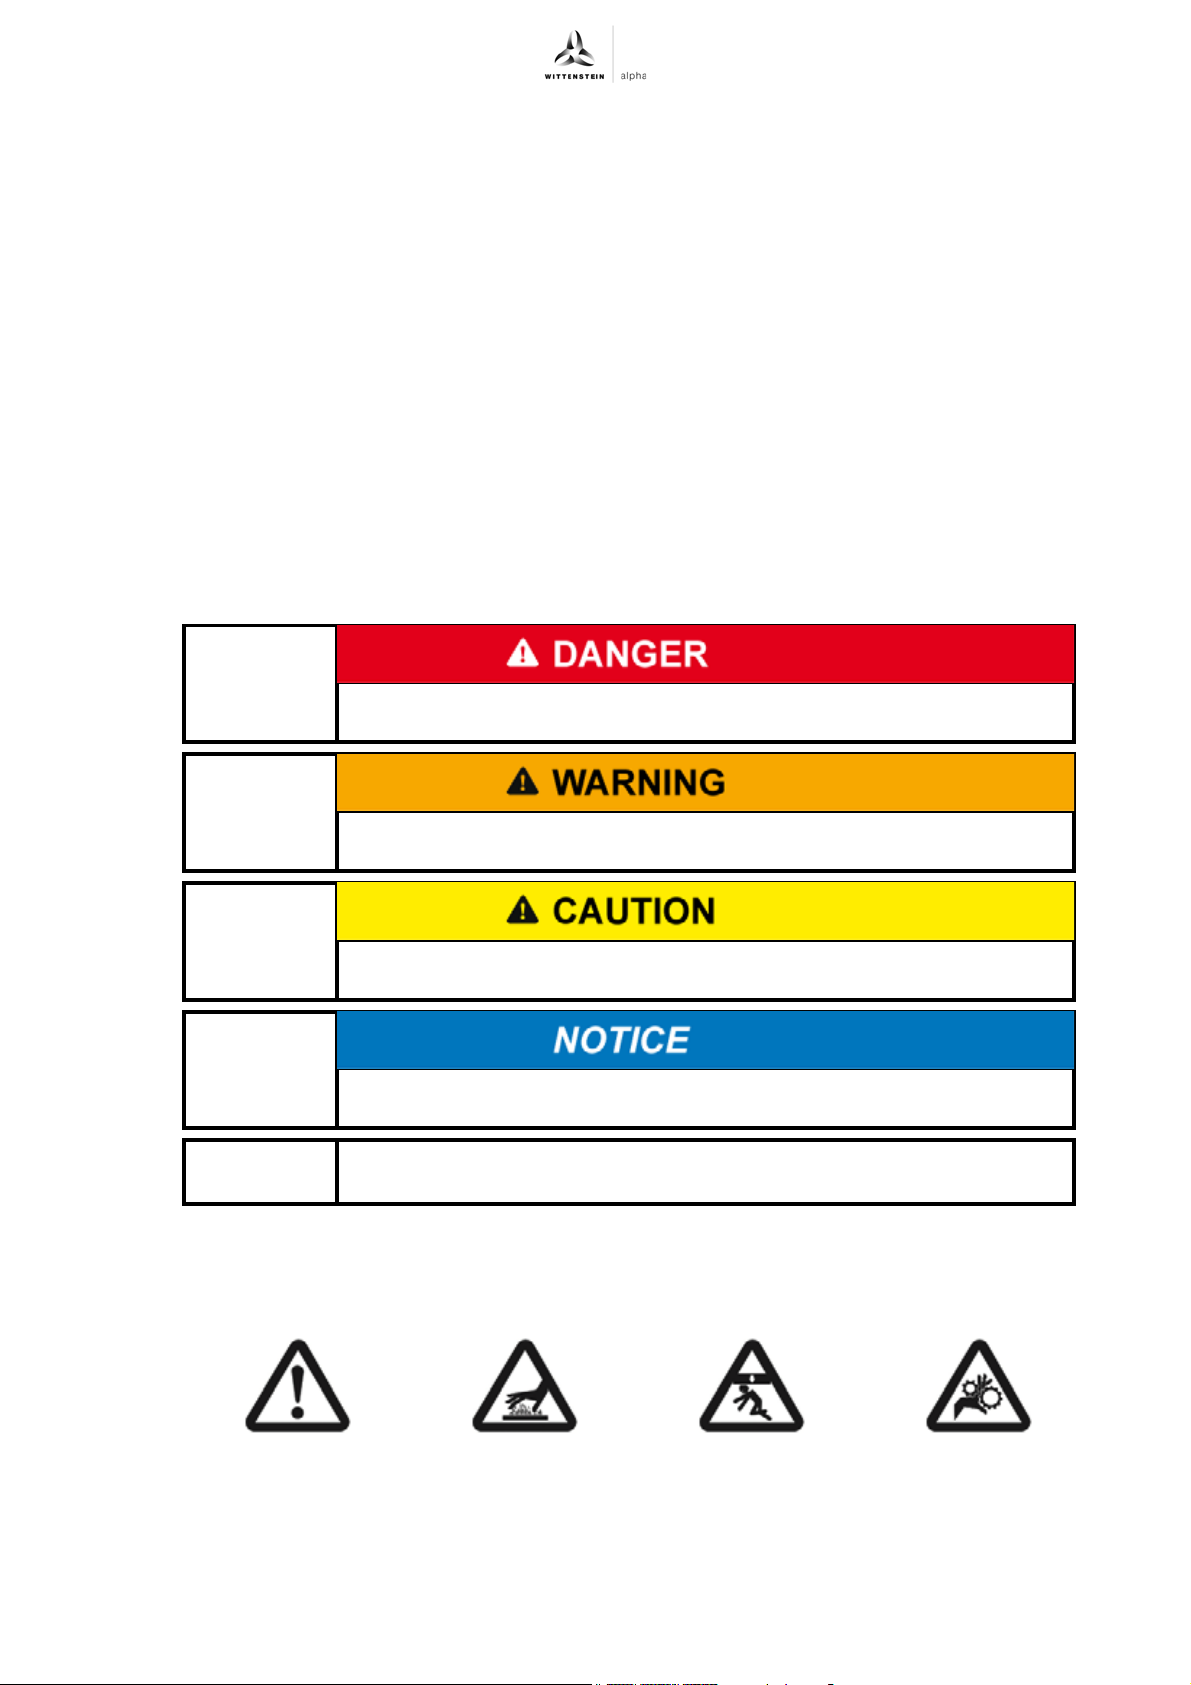
1.1 Signal words
The following signal words are used to indicate possible hazards, prohibitions, and important
information:
About this manual
1.2 Safety symbols
The following safety symbols are used to bring your attention to dangers, prohibitions, and
important information:
This signal word points out to an imminent danger that can cause
serious injuries and even death.
This signal word points out to a possible danger that can cause
serious injuries and even death.
This signal word points out to a possible danger that can cause slight
to serious injuries.
This signal word points out to a possible danger that can cause
material damage.
A note without signal word draws your attention to application tips or
especially important information when handling the servo actuator.
General danger Hot surface Suspended loads Danger of being pulled
in
Revision: 07 4022-D018396 en-5
Page 6
About this manual TPM
+
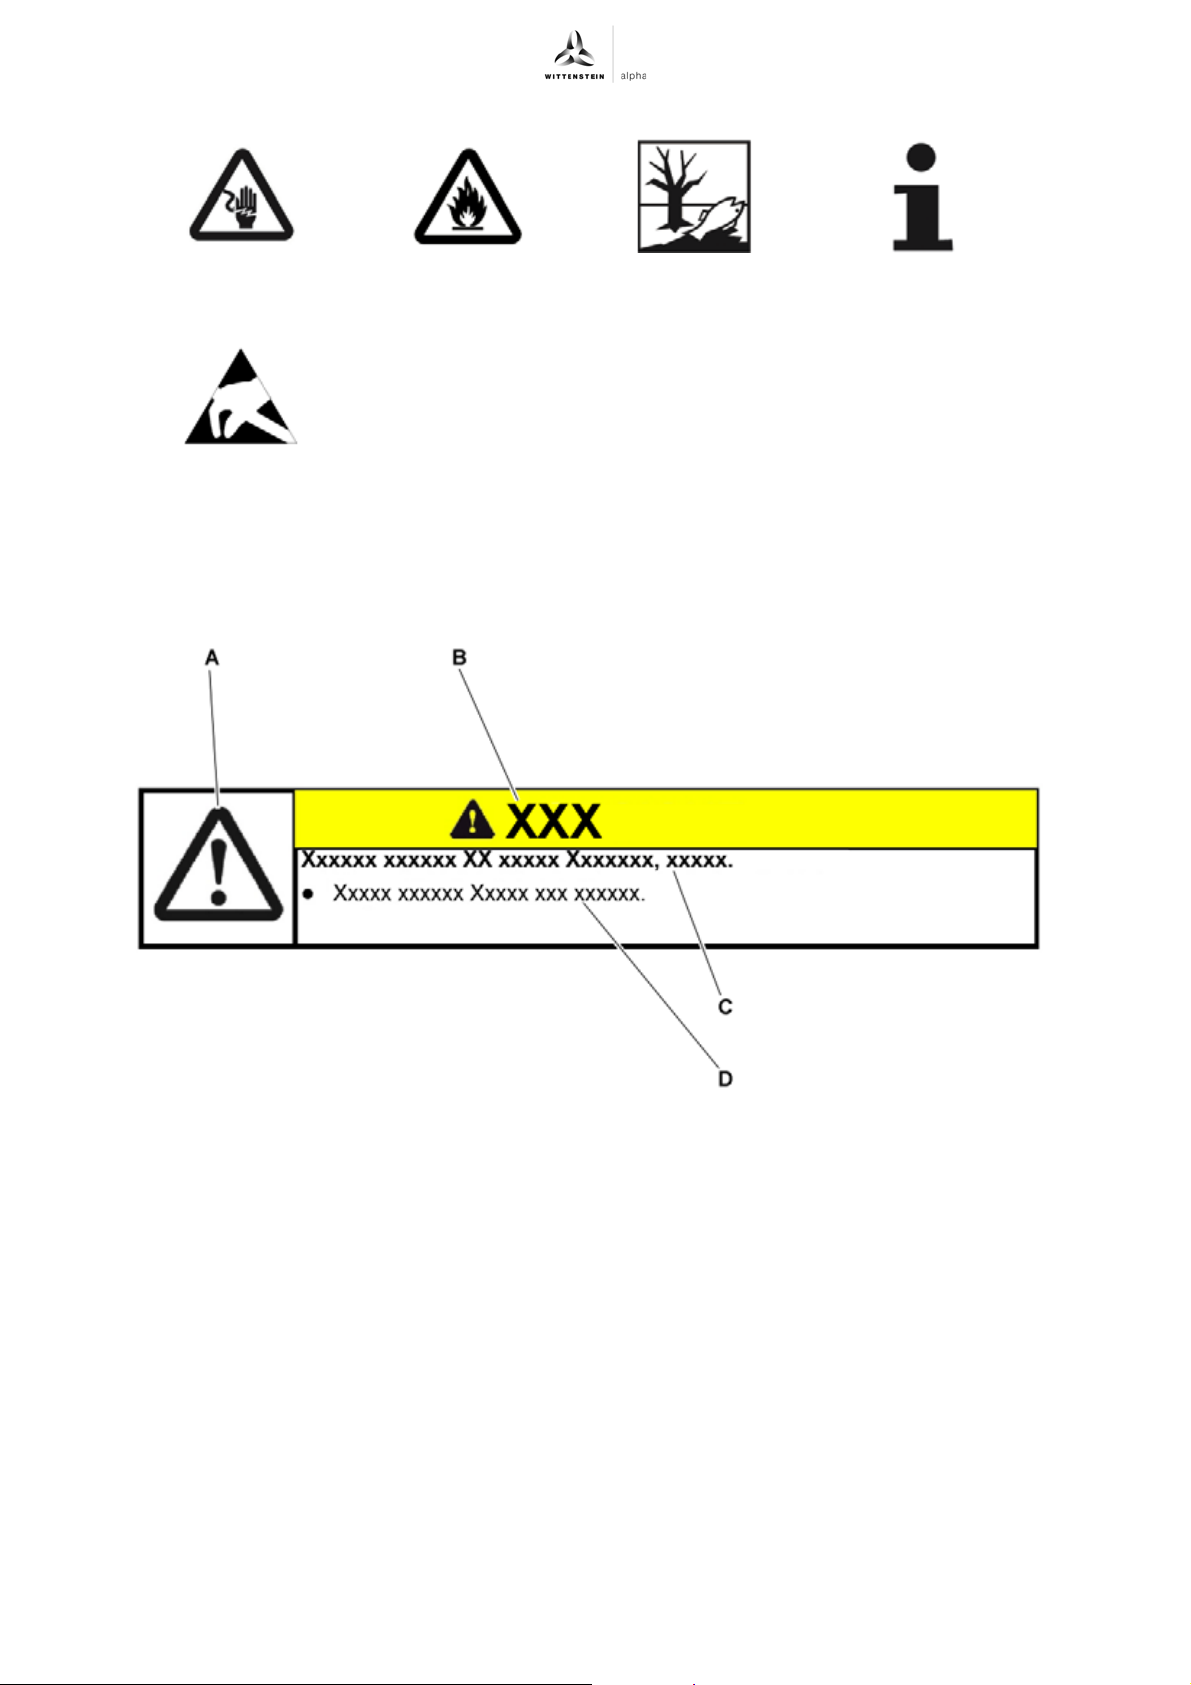
Electric voltage Flammable Harmful to the
Component sensitive
to electrostatic
discharge
1.3 Design of the safety instructions
The safety instructions of these instructions are designed according to the following pattern:
Information
environment
A = Safety symbol (see Chapter 1.2 "Safety symbols")
B = Signal word (see Chapter 1.1 "Signal words")
C = Type and consequence of the danger
D = Prevention of the danger
1.4 Information symbols
The following information symbols are used:
Indicates an action to be performed
Indicates the results of an action
Provides additional information on handling
en-6 4022-D018396 Revision: 07
Page 7
+
TPM
2 Safety
This operating manual, especially the safety instructions and the rules and regulations valid for the
operating site, must be observed by all persons working with the servo actuator.
In addition to the safety instructions in this manual, also observe any (legal and otherwise)
applicable environmental and accident prevention rules and regulations (e.g. personal safety
equipment).
2.1 EU Low Voltage Directive
The servo actuator has been constructed in accordance with the directive 2014/35/EU. Observe
applicable regulations for electrical installation (e.g. wire gauge, fuses).
It is the responsibility of the manufacturer of the plant to ensure all requirements for the entire
system are fulfilled.
2.2 Dangers
The servo actuator has been constructed according to current technological standards and
accepted safety regulations.
To avoid danger to the operator or damage to the machine, the servo actuator may be put to use
only for its intended usage (see Chapter 2.4 "Intended use") and in a technically flawless and safe
state.
Read the general safety instructions before beginning work (see Chapter 2.7 "General safety
instructions").
Safety
2.3 Personnel
Only technicians who have read and understood this operating manual may perform work on the
servo actuator. Based on their training and experience, technicians must be able to evaluate the
tasks assigned to them, in order to recognize and avoid risks.
2.4 Intended use
The servo actuator is designed to be installed in or connected to the following machines, incomplete
machines or equipment:
- Stationary large-scale plant,
- Stationary industrial tools,
- Movable machines, not intended for road use and only provided for professional (industrial)
use
In particular the following points must be observed:
- The servo actuator must be controlled by a servo controller.
- T he servo actuator must not be used in applications with special environmental conditions e .g.
vacuum, potentially explosive atmospheres, clean room or areas with radioactive
contamination.
- A dditional point s must be observed for use in the food industry or the pharmaceutical industry:
- The servo actuator may only be used next to or under the foodstuff/product area.
- Observe also 7.4 "Information on the lubricant used".
- F or risk-free operation, required safety devices have to be prese nt, properly installed, and fully
functional. They may not be removed, changed, bridged, or rendered ineffective.
- In case of an emergency shutdown, power failure and or damage to the electrical equipment,
the servo actuator must be
- switched off immediately,
- secured against uncontrolled re-activation,
- secured against uncontrolled after-running.
- T he optionally installed brake is simply a holding brake and may only be utilized in emergency
stop situations for braking the running servo actuator.
Revision: 07 4022-D018396 en-7
Page 8
Safety TPM
2.5 Reasonably foreseeable misuse
Any use that deviates from the approved technical data (e.g. speed, force, torque, temperature) is
not use as intended and is therefore not permitted.
In particular the following applications are not permitted:
- Operation of the servo actuator, without properly installing it in or connecting it to other
machines or other partly completed machines or equipment.
- Operation of the servo actuators in a defective state
- Operation of the servo actuator, without determining that the machine in which it is to be
installed complies with the provisions of the Machinery Directive 2006/42/EC.
- Operation of the servo actuator in a potentially explosive environment
- Assembly of the servo actuator without prior acknowledgment of the operating / assembly
manual
- Operation of the servo actuator without legible warning and information signs
- Use of improper lubricants
- Use of unsuitable servo controllers
- Use in improper installation, operating, performance and ambient conditions
- Assembly of the servo actuator by insufficiently competent personnel
+
2.6 Guarantee and liability
Guarantee and liability claims are excluded for personal injury and material damage in case of
- Ignoring the information on transport and storage
- Improper use (misuse)
- Improper or neglected maintenance and repair
- Improper assembly / disassembly or improper operation (e.g. test run without secure
attachment)
- Operation of the servo actuator when safety devices and equipment are defective
- Operation of the servo actuator without lubricant
- Operation of a heavily soiled servo actuator
- Modifications or reconstructions that have been carried out without the approval of
WITTENSTEIN alpha GmbH
2.7 General safety instructions
Faulty electrical connections or not approved, current-carrying
components can cause serious injuries and even death.
Have all electrical connection work performed by qualified technicians
only.
Immediately replace damaged cables or plugs.
During generator operation, voltage is induced. This can lead to lethal
current pulses.
Ensure that no plugs and connections are laying open during generator
operation.
en-8 4022-D018396 Revision: 07
Page 9
TPM
+
Safety
Objects flung out by rotating components can cause serious injuries.
Remove objects and tools from the servo actuator before putting it into
operation.
Rotating components on the servo actuator can pull in parts of the
body and cause serious injuries and even death.
Keep a sufficient distance to rotating machinery while the servo actuator
is running.
Secure the machine against restarting and unintentional movements
during assembly and maintenance work (e.g. uncontrolled lowering of
lifting axes).
A damaged servo actuator can cause accidents with the risk of injury.
Never operate a servo actuator that has been overloaded due to misuse
or a machine crash (see Chapter 2.5 "Reasonably foreseeable misuse").
Replace the affected servo actuators, even if no external damage is
visible.
Hot servo actuator housing (up to 125 °C) can cause serious burns.
Touch the servo actuator housing only when wearing protective gloves
or after the servo actuator has been idle for some time.
Loose or overloaded screw connections can damage the servo
actuator.
Always use a calibrated torque wrench to tighten and check all screw
connections for which a tightening torque has been specified.
Lubricants are flammable.
Do not spray with water to extinguish.
Suitable extinguishing agents are powder, foam, water mist, and carbon
dioxide.
Observe the safety instructions of the lubricant manufacturer (see
Chapter 7.4 "Information on the lubricant used").
Solvents and lubricants can cause skin irritations.
Avoid direct skin contact.
Revision: 07 4022-D018396 en-9
Page 10
Safety TPM
Solvents and lubricants can pollute soil and water.
Use and dispose of cleaning solvents and lubricants properly.
2.8 Safety signs
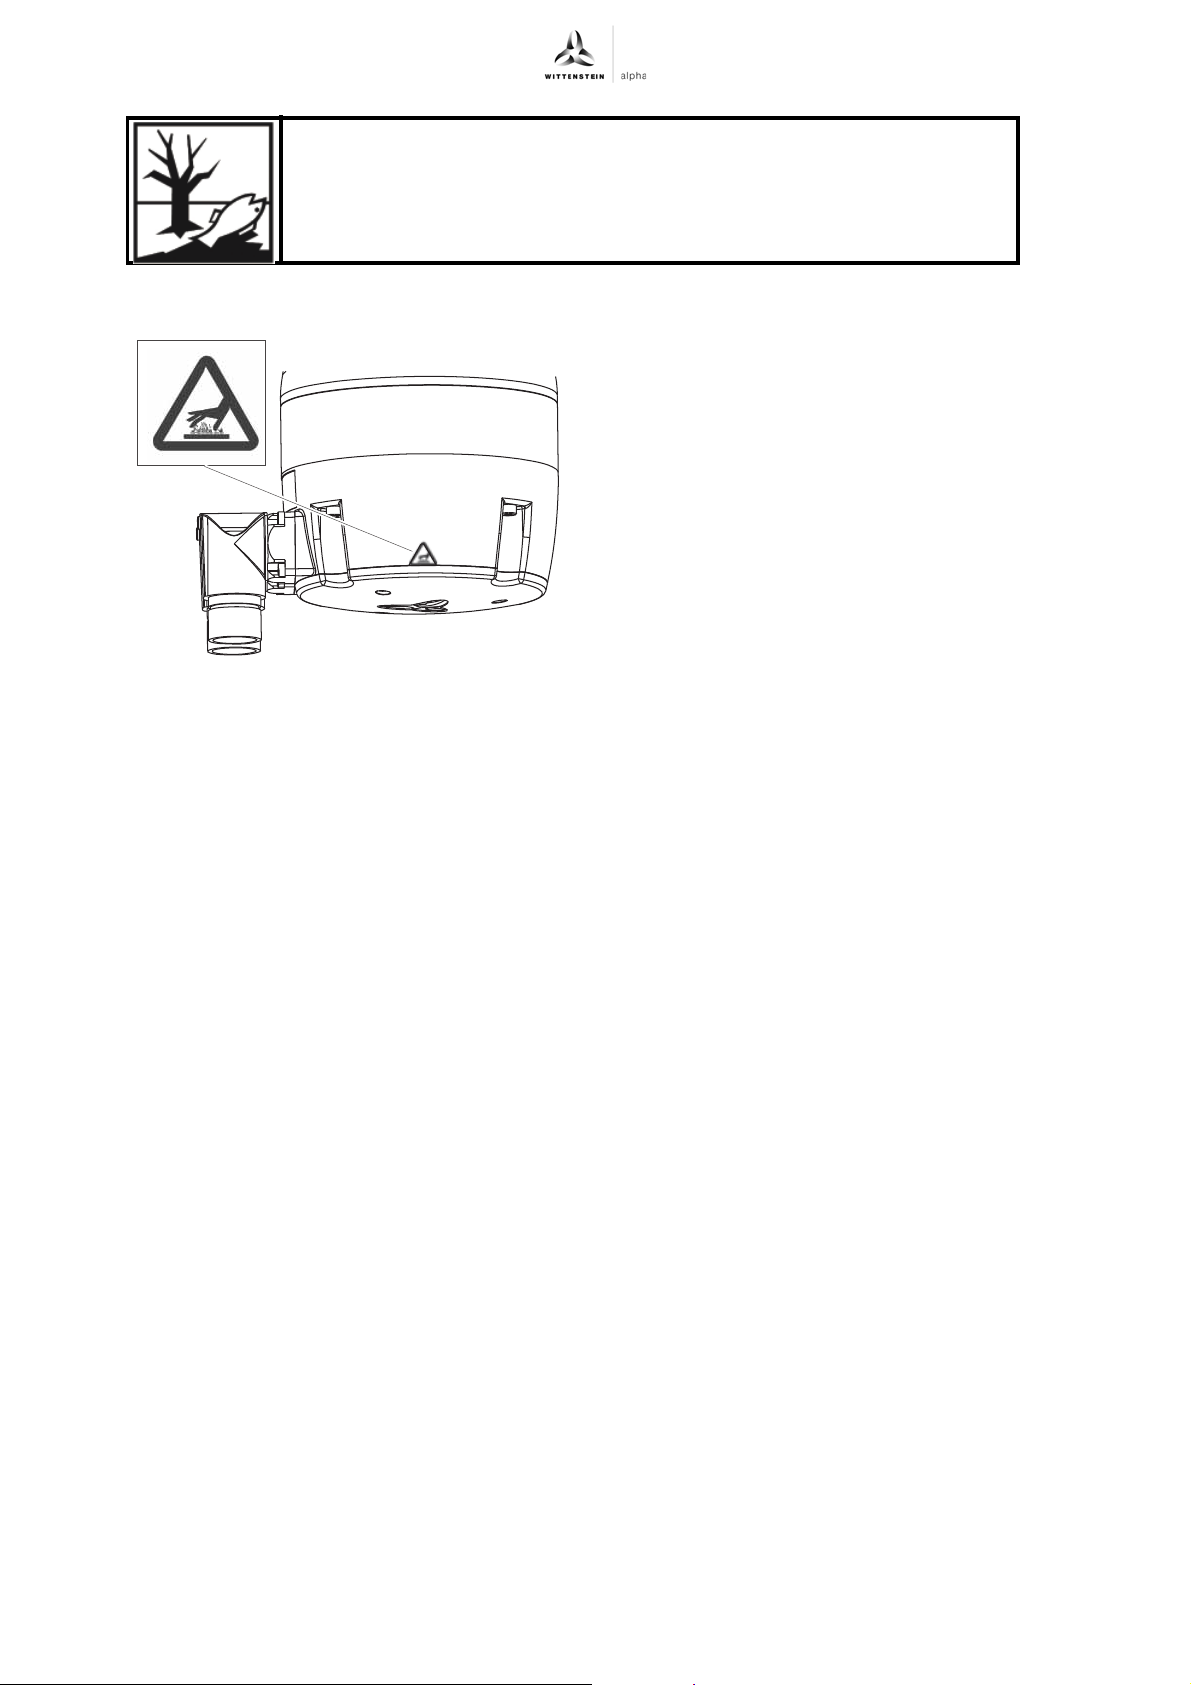
There is a safety sign on the servo actuator
housing that warns against hot surfaces. This
safety sign may not be removed.
+
en-10 4022-D018396 Revision: 07
Page 11
+
C
G
A
D
E
B
F
J
Q
M
I
HL
TPMA050S-027R-6PO1-155D-W1-000
560
17,9
Oil Tribol 800/220 Pos: xxx
452
63,5
950
-
27,5
56,6
5000
164
KW/JJ
xxxxxxxx
xxxxxxxx
xxxxxxxx
65
xxx
4xxx xxxx
K
R
O
PS
N
T
TPM
3 Description of the servo actuator
The AC servomotor is a brushless 3-phase synchronous motor with excitation by means of
permanent magnets located on the rotor. A resolver or optical encoder takes care of the
commutation or speed regulation. An optional permanent-magnet holding brake is integrated into
the motor.
Description of the servo actuator
The servo actuator is a combination of a lowbacklash planetary gearhead (B) and an AC
servomotor (A).
The output bearing is designed to receive high
external tilting moments.
There are two centering mechanisms for the output
flange.
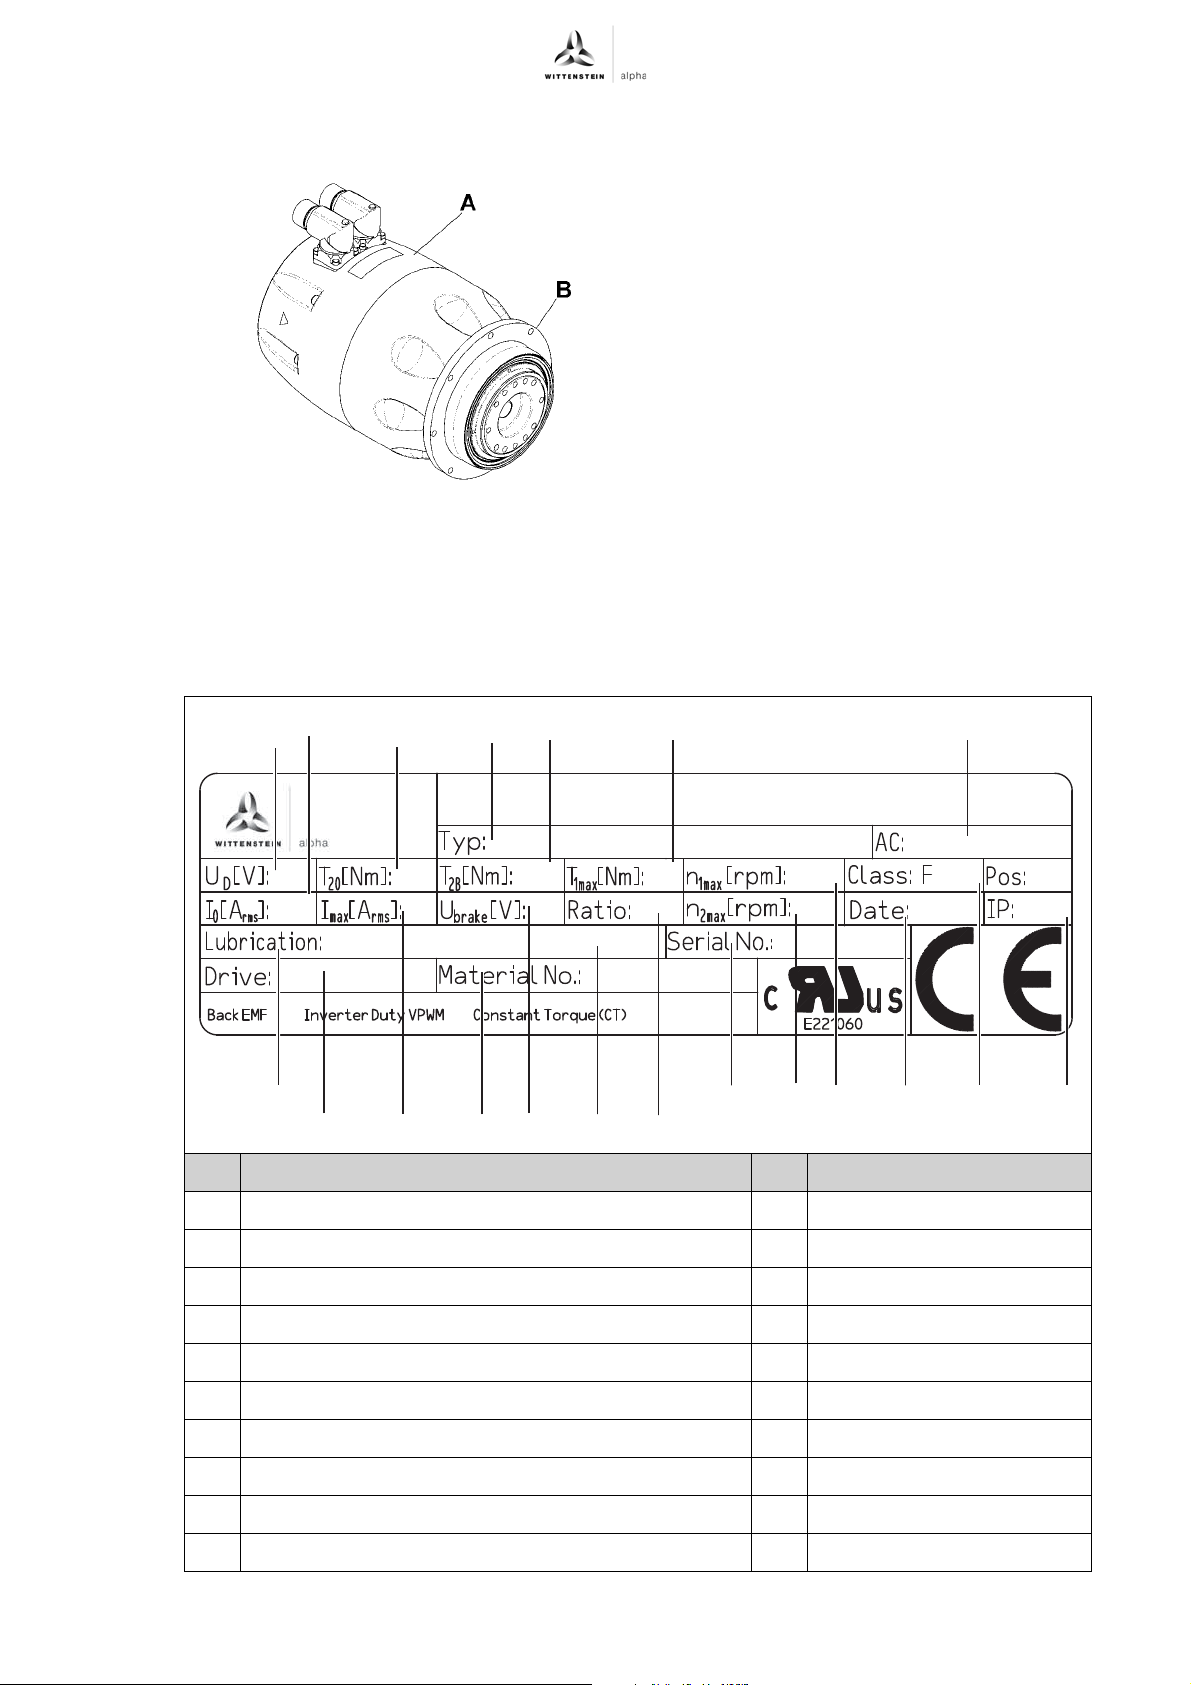
3.1 Identification plate
The identification plate is attached to the servo actuator housing.
A Ordering code (see 3.2 "Ordering code") K Lubrication
WITTENSTEIN alpha GmbH - Walter-Wittenstein-Str.1 - D97999 Igersheim
Designation Designation
Revision: 07 4022-D018396 en-11
B Article code L Mounting position
C Intermediate voltage M Max. speed
D Continuous stall torque at gear output N Max. speed of the motor
E Maximum acceleration torque at the gear output O Protection class
F Max. acceleration torque of the motor P Insulation class
G Continuous stall current of the motor Q Servo converter
H Max. acceleration current of the motor R Production date
I Brake voltage S Serial number
J Gearhead ratio T Material number (customer)
Tbl-1: Identification plate
Page 12
Description of the servo actuator TPM
Actuator type
TPM
Version
_ = dynamic
A = high torque
P = power
Size
004/010/025/050/110
Version
S = Standard UL
G = Grease filling
F = Food-grade lubrication
X = Special design
P = Welded pinion
Ratio i
Feedback system
R = Resolver 2-pole
S = Singleturn absolute encoder, EnDat
M = Multiturn absolute encoder, EnDat
N = Singleturn absolute encoder, Hiperface
K = Multiturn absolute encoder, Hiperface
T = 5V-TTL -Incremental encoder with
Hall-signal
E = Singleturn absolute encoder,
Rockwell compatible
V = Multiturn absolute encoder,
Rockwell compatible
I = Incremental encoder, optical
Pin configuration
1 = Standard, temperature
sensor over signal
cable
4 = Temperature sensor
over power cable
5 = Rockwell compatible
6 = B&R compatible
Electrical connection
W = Angular mounting box
G = Mounting box, straight
Motor size and stator
length
Backlash
1 = Standard
0 = Reduced
Brake
B = with brake
O = without brake
Temperature sensor
P = PTC
K = KTY
DC bus voltage
5 = 320V
6 = 560V
TPM 010S-100R -6PB1-055A-W1
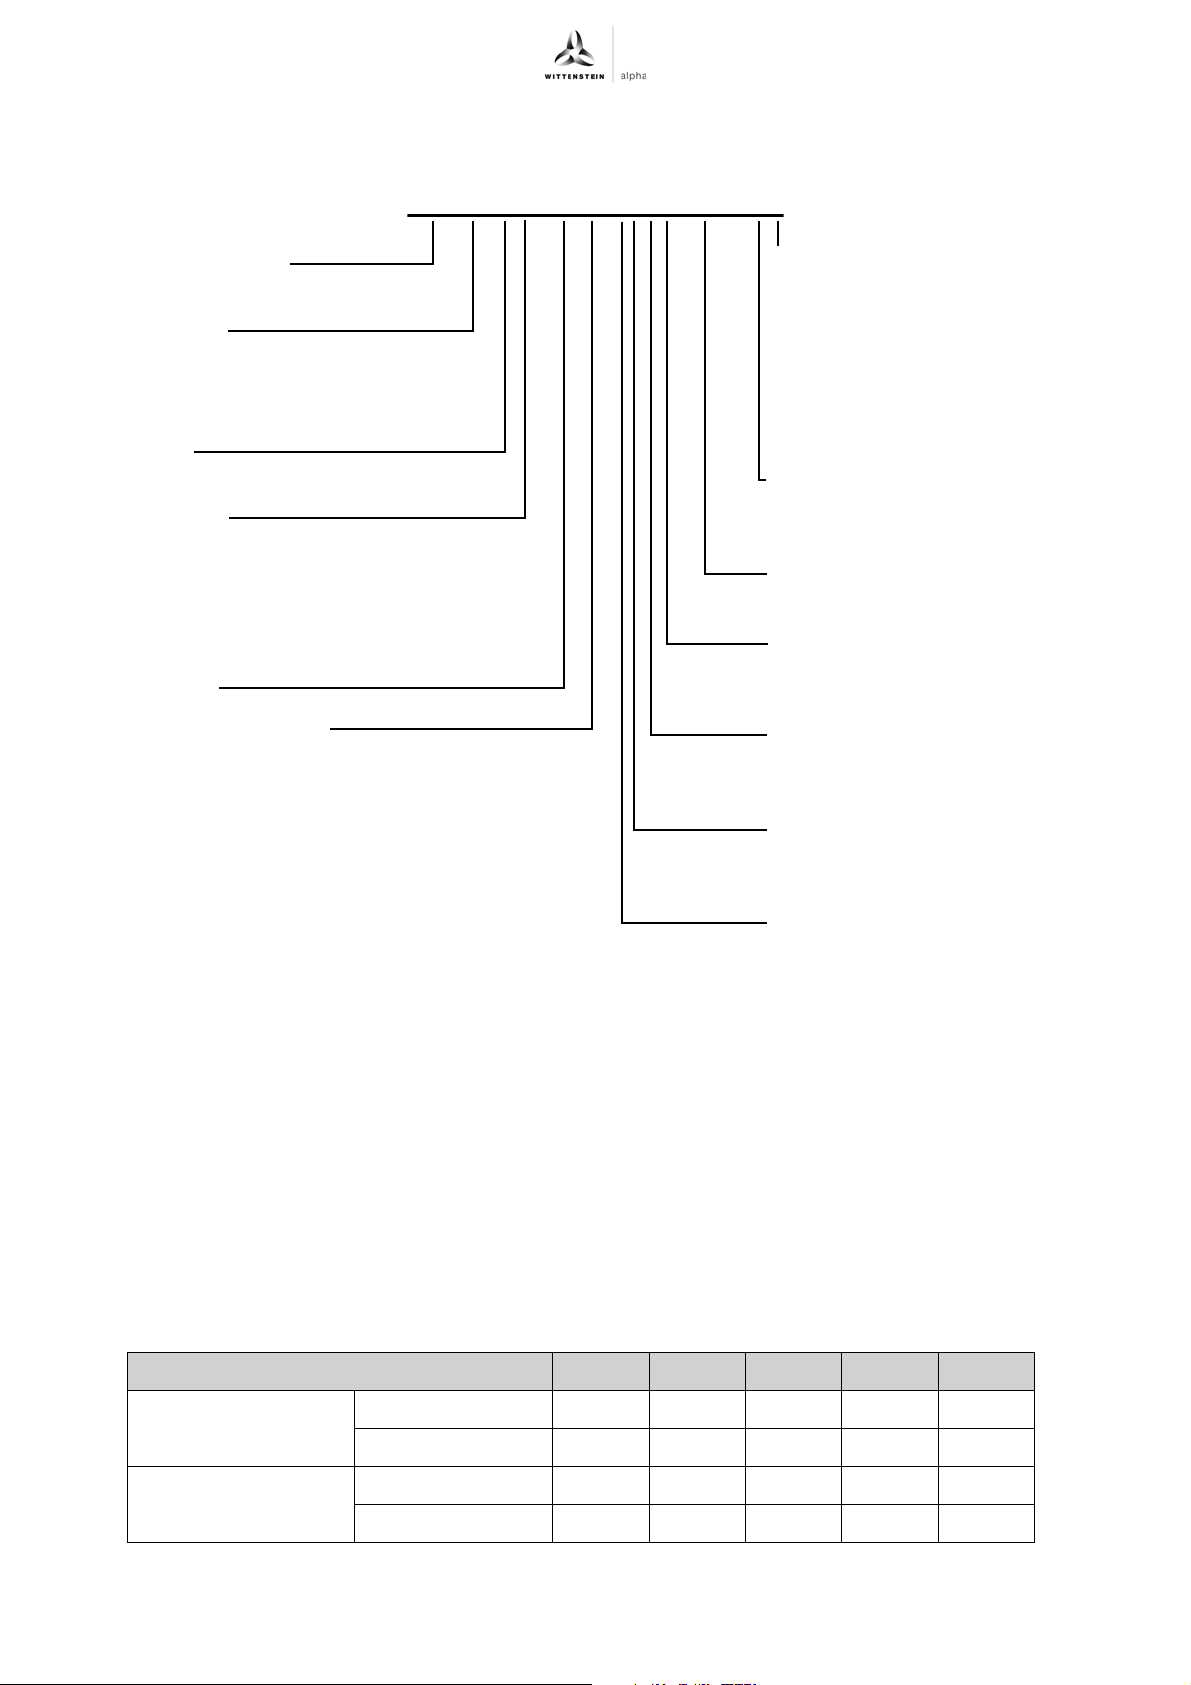
3.2 Ordering code
+
3.3 Performance statistics
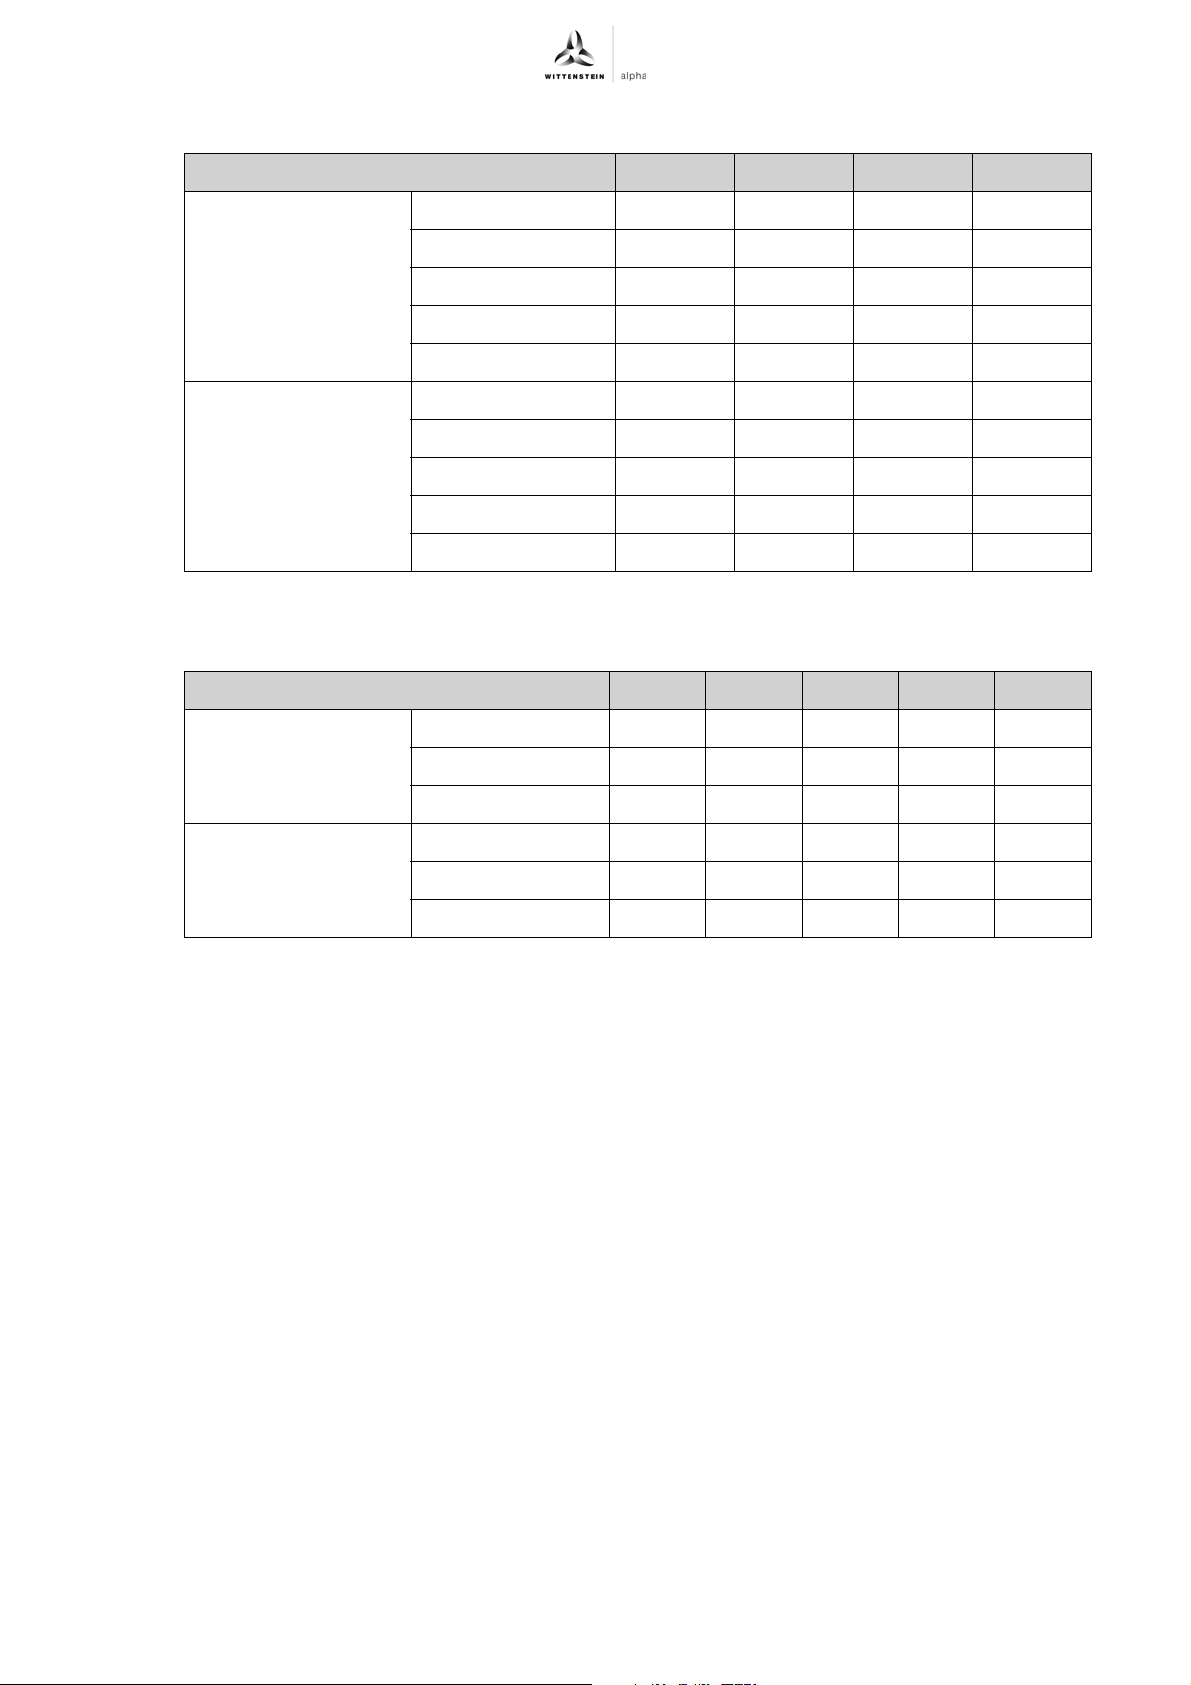
3.4 Weight
Refer to Chapter 9.4 "Technical specifications" for the maximum permitted speeds and torques.
The standard weights of the servo actuators are specified in the tab les "Tbl-2", "Tbl-3" and "Tbl-4"
(with resolver, without brake). Depending on the design, the actual dimension can deviate by up to
20 %.
3.4.1 Weight TPM
Without brake [kg] i = 16 –31 2.2 4.8 8.5 18.5 37.1
With brake [kg] i = 16 –31 3 5.3 9.8 23.7 39.6
+
dynamic
Size TPM
+
i = 61 –91 2 4.3 7.1 14.7 35.9
i = 61 –91 2.7 4.9 8.4 16.2 38.3
Tbl-2: Weight [kg]
en-12 4022-D018396 Revision: 07
004 010 025 050 110
Page 13
+
TPM
3.4.2 Weight TPM+ high torque
Size TPM
Without brake [kg] i = 22 –55 7.6 14.8 25.3 76.8
With brake [kg] i = 22 –55 8.1 15.9 27.5 80.0
Description of the servo actuator
+
i = 66 – 10.0 21.8 63.8
i = 88 8.0 10.0 21.8 63.8
i = 110 8.0 10.0 21.8 45.5
i = 154, 220 6.5 10.0 21.8 45.5
i = 66 – 10.5 22.9 67.0
i = 88 8.5 10.5 22.9 67.0
i = 110 8.5 10.5 22.9 46.8
i = 154, 220 7.0 10.5 22.9 46.8
Tbl-3: Weight [kg]
010 025 050 110
3.4.3 Weight TPM
Without brake [kg] i = 4 –10 3.6 7.2 14.0 23.6 58.8
With brake [kg] i = 4 –10 4 7.7 15 24.9 62.0
+
power
Size TPM
+
004 010 025 050 110
i = 16 –35 3.7 7.4 14.5 25.1 59.6
i = 40 –100 3.3 6.0 10.3 19.4 52.3
i = 16 –35 4.1 7.9 15.5 26.4 62.8
i = 40 –100 3.7 6.5 11.3 20.7 55.5
Tbl-4: Weight [kg]
Revision: 07 4022-D018396 en-13
Page 14
Transport and storage TPM
4 Transport and storage
4.1 Scope of delivery
Check the completeness of the delivery against the delivery note.
Missing parts or damage must be notified immediately in writing to the carrier, the
insurance company, or WITTENSTEIN alpha GmbH.
4.2 Packaging
The servo actuator is delivered packed in foil and cardboard boxes.
Entsorgen Sie die Verpackungsmaterialien an den dafür vorgesehenen Entsorgungsstellen.
Observe the locally valid regulations for disposals.
4.3 Transport
Suspended loads can fall and can cause serious injuries and even
death.
Do not stand under suspended loads.
Secure the servo actuator with suitable fasteners (e.g. belts) before
transport.
+
Specifications on the weights, refer to Chapter 3.4 "Weight".
Ambient temperatures between -20° C and +50° C are permissible for transport only.
4.4 Storage
Store the servo actuator in horizontal position and dry surroundings at a temperature of 0C to +
30C in the original packaging. Store the servo actuator for a maximum of 2 years.
For storage logistics, we recommend the "first in –first out" method.
Hard knocks, because of falling or hard dropping, can damage the
servo actuator.
Only use hoisting equipment and transports with sufficient capacity.
The maximum permitted lift capacity of a hoist may not be exceeded.
Lower the servo actuator slowly.
en-14 4022-D018396 Revision: 07
Page 15
+
TPM
5 Assembly
Read the general safety instructions before beginning work (see Chapter 2.7 "General safety
instructions").
5.1 Preparations
Assembly
Many electronic components are sensitive against electrostatic
discharge (ESD). This concerns in particular integrated circuits (IC),
semiconductors, resistors with a tolerance of less than one percent as
well as transistors and other components such as encoders.
Observe the directives concerning ESD protection.
Pressurized air can damage the servo actuator seals.
Do not use pressurized air to clean the servo actuator.
Clean/de-grease the output shaft /output flange of the servo actuator with a clean, lint-free
cloth moistened with a suitable grease-dissolving but non-aggressive cleaning agent.
Dry all fitting surfaces to neighboring components in order to achieve the proper friction values
of the screw connections.
Check the fitting surfaces additionally for damage and impurities.
5.2 Mounting the servo actuator onto a machine
The servo actuator is compliant for every mounting position; the
lubricant quantity, however, is dependent on the mounting position.
The mounting position and the lubricant that has been filled in is
indicated on the identification plate (see Chapter 3.1 "Identification
plate").
Mount the servo actuator only in the specified mounting position.
Observe the safety and processing instructions for the threadlocker to be
used.
Revision: 07 4022-D018396 en-15
Page 16
Assembly TPM
A
B
+
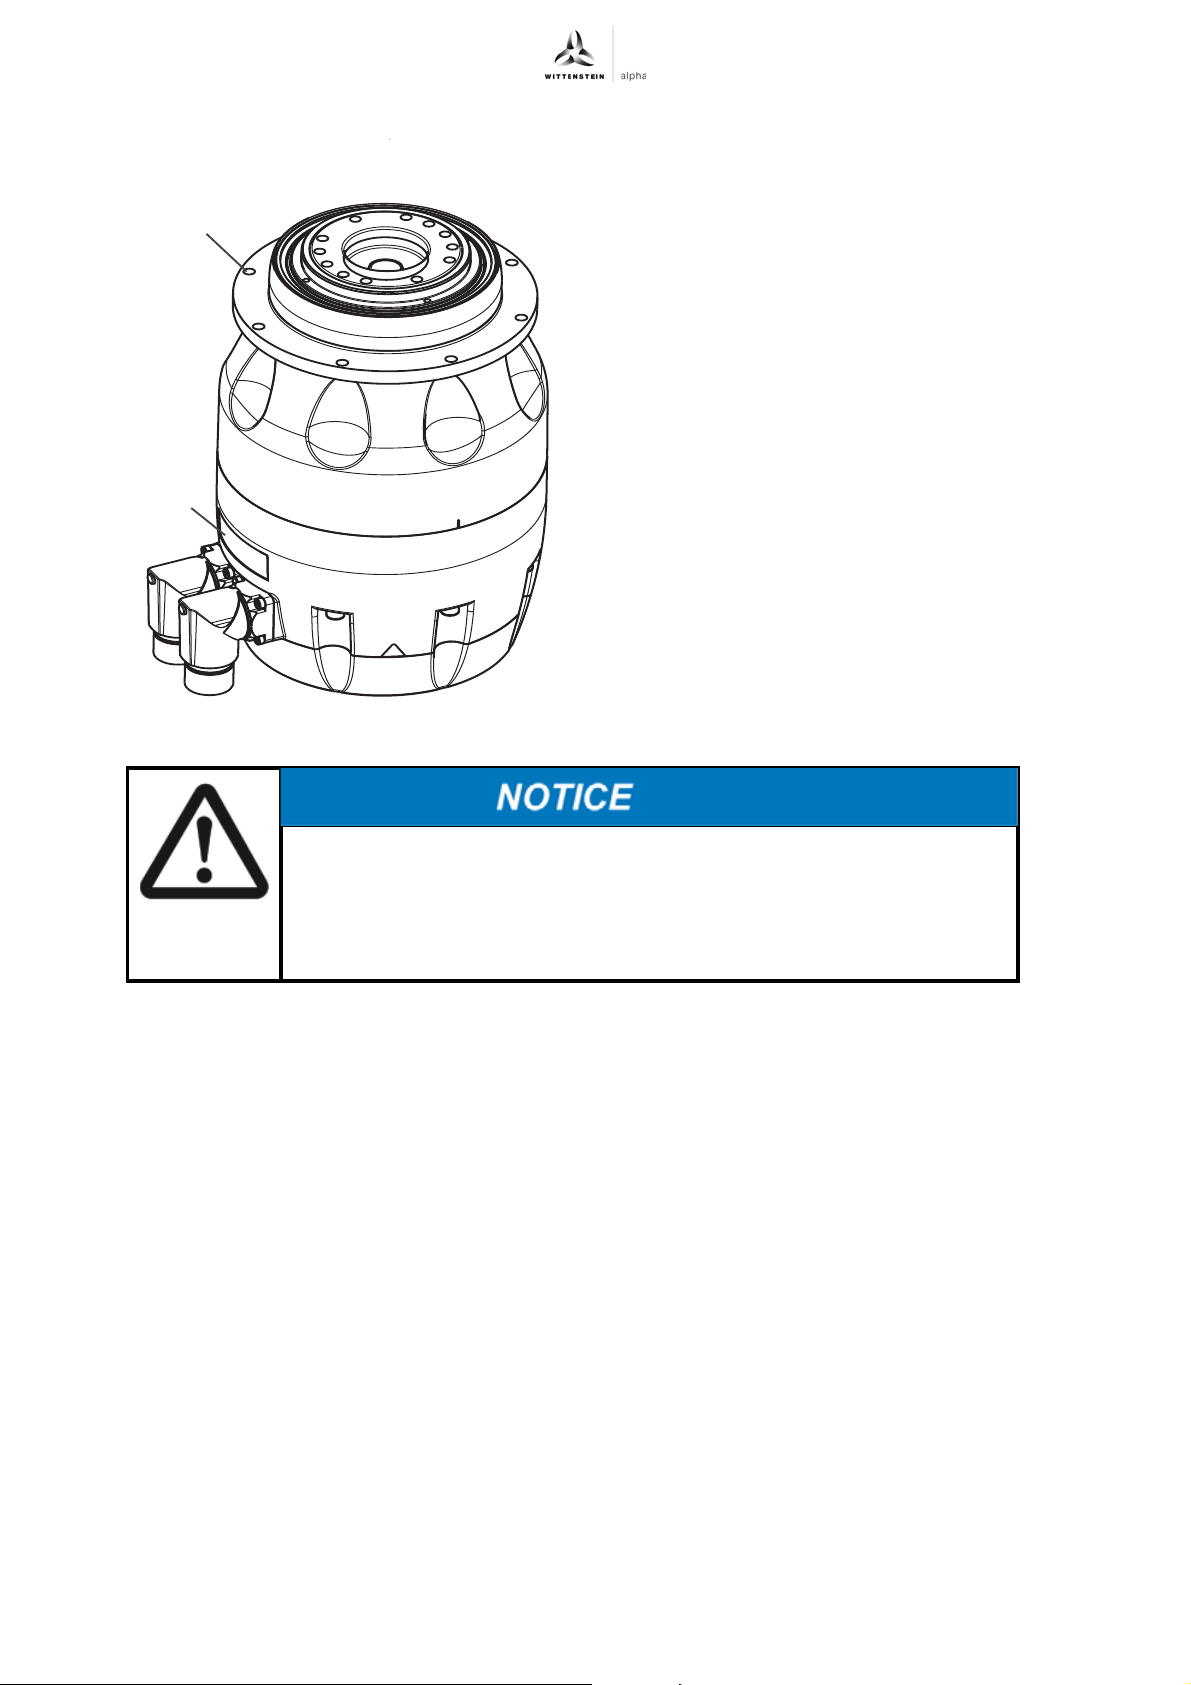
Coat the fastening screws with a threadlocker
(e.g. Loctite
Fasten the servo actuator to the machine with
®
243).
the fastening screws through the throughholes (A).
Mount the servo actuator in such a way that
the type plate (B) remains legible.
Do not use washers (e.g. plain washers,
tooth lock washers).
For specified screw sizes and tightening
torques, see Chapter 9.1 "Specifications on
mounting onto a machine", Tables "Tbl-11"
and "Tbl-12".
5.3 Components mounted on the output side
Distortions during assembly can damage the servo actuator.
Mount gearwheels and toothed belt pulleys onto the output flange
without forcing.
Never attempt to assemble by force or hammering!
Only use suitable tools and devices for assembly.
The prescribed screw sizes and tightening torques for the output flange can be found in
Chapter 9.2 "Specifications on mounting on the gear output side", Tables "Tbl-13", "Tbl-14"
and "Tbl-15".
en-16 4022-D018396 Revision: 07
Page 17
+
TPM
5.4 Installing electrical connections
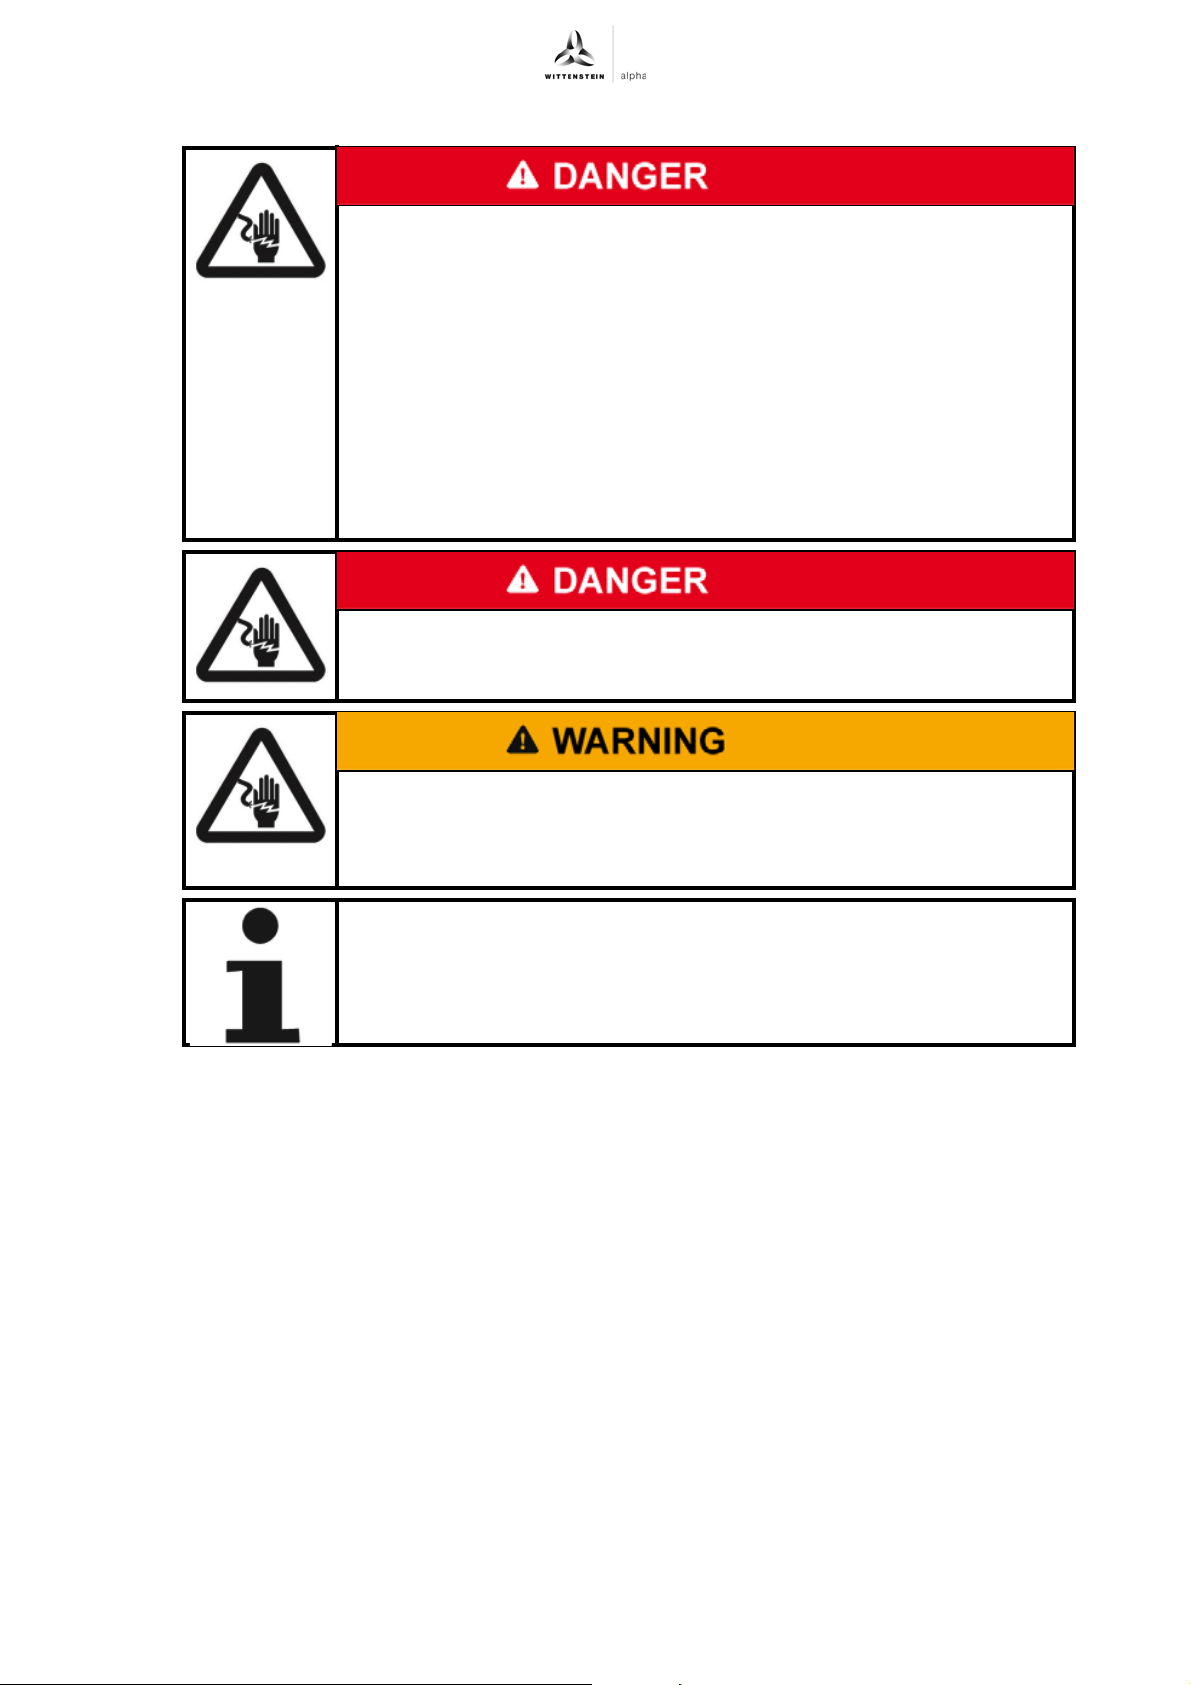
Electrically live components may result in electric shocks if touched
and can cause serious injuries and even death.
Observe the five safety rules of electrical engineering before starting
electrical installation work:
- Disconnect.
- Secure against being switched on again.
- Check that there is no voltage.
- Ground and short-circuit.
- Cover neighboring and electrified parts.
Check that protective caps are on the plugs. If protective caps are
missing, check the plugs for damage and soiling.
Electric operation in moist areas may result in electric shocks and can
cause serious injuries and even death.
Carry out the electrical assembly only in dry areas.
Assembly
During generator operation, voltage is induced. This can lead to lethal
current pulses.
Ensure that no plugs and connections are exposed during generator
operation.
The cables of all servo actuators need to be laid out in such a way that
a minimum bending radius of 10 x diameter is kept. Torsional load of
the cables should be avoided.
speedtec-ready connectors are used in actuators of the respective series. These are speedtec
connectors with an additional vibration O-ring.
- When using M23 screw counter plugs, the O-ring remains in place to protect against
loosening due to vibration on the mounting socket.
- When using Speedtec counter plugs the O-ring must be removed.
- The maximum line length without disconnection points is 50 m. Observe also the maximum
permissible line lengths of the servo converter being used.
Revision: 07 4022-D018396 en-17
Page 18
Startup and operation TPM
6 Startup and operation
6.1 Safety instructions and operating conditions
Read the general safety instructions before beginning work (see Chapter 2.7 "General safety
instructions").
Wearing hearing protection in the vicinity of the servo actuator is recommended.
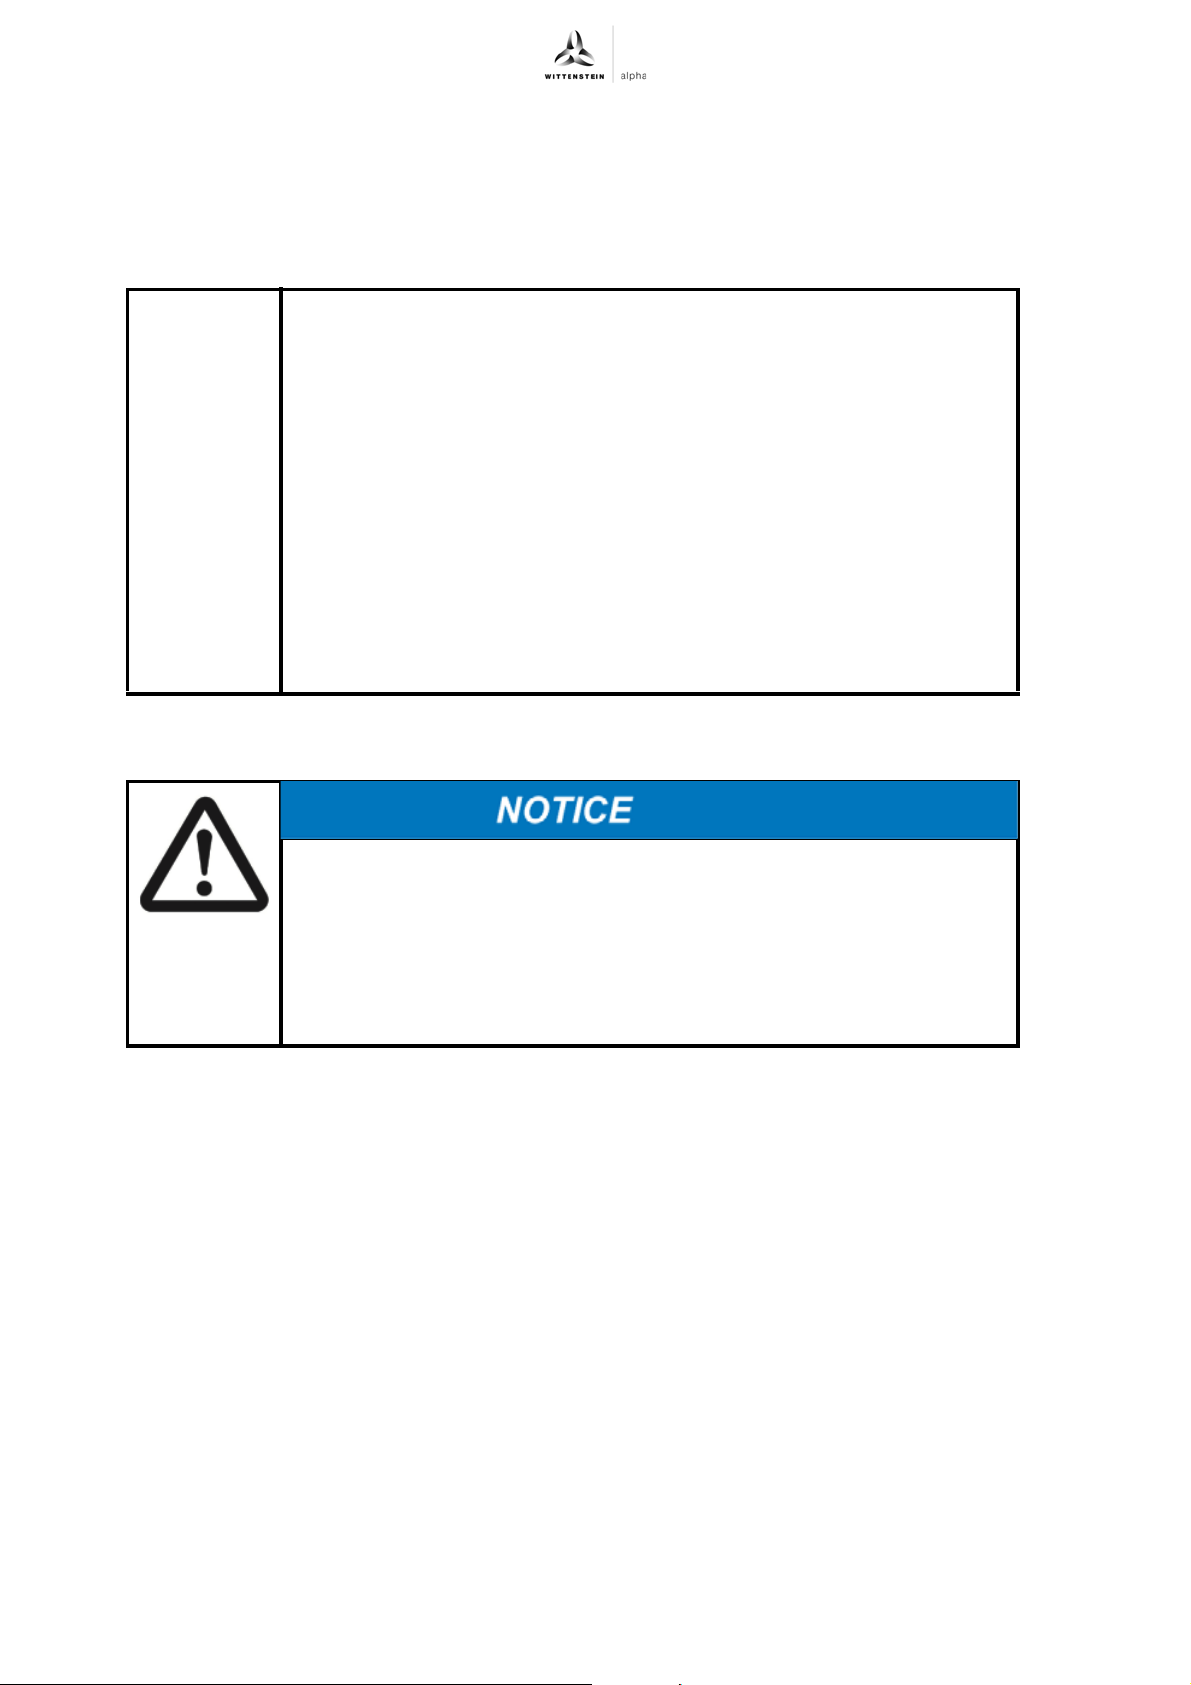
Improper use can cause damage to the servo actuator.
Ensure that
- The ambient temperature does not drop below 0 °C or exceed
+40 °C,
- The surface temperature on the gearhead does not exceed +90°C,
- The surface temperature on the engine does not exceed +115°C,
- The installation altitude is not above 1000 m NHN.
For other conditions of use, consult our Customer Service department.
Use the sensor only up to its maximum limit values, see Chapter 9.4
"Technical specifications".
Only use the servo actuator in a clean, dust-free and dry environment.
Operate the servo actuator only in the mounting position that is specified
on the identification plate.
+
6.2 Data for the electrical startup
The specified data is intended for the electrical startup.
The servo controllers of the different manufacturers generally use an
individual annotation of the data.
If the data is disregarded, the drive and/or the servo controller may be
damaged.
Observe the listed units precisely and check their conformance with the
units of the servo controller.
If the units differ, make the necessary adjustment accordingly.
In some servo controllers, there is a dependence between the individual parameters. We would
be glad to assist you in finding the correct entries.
We provide adjusted and certified quick start guides for several servo controllers. In these
guides you will find the adapted parameter lists for the relevant servo converters.
For further information, please visit our website at http://wittenstein-alpha.de or contact our
Customer Service: [email protected]
This data reflects the technical characteristics and the limit values of the standard engines of the
+
TPM
- series in general units. Possible restrictions due to the gearhead can be found in the data
sheet of your servo actuator.
Select the data for the TPM
- Chapter 9.4.4 "Motor data, TPM
- Chapter 9.4.5 "Motor data, TPM
- Chapter 9.4.6 "Motor data, TPM
- Chapter 9.4.7 "Motor data, TPM
- Chapter 9.4.8 "Motor data, TPM
- Chapter 9.4.9 "Motor data, TPM
- Chapter 9.4.10 "Motor data, TPM
+
- version you are using.
+
dynamic 320V, i = 16 – 31"
+
dynamic 320V, i = 61 – 91"
+
high torque 320V"
+
power 320V"
+
dynamic 560V, i = 16 – 31"
+
dynamic 560V, i = 61 – 91"
+
high torque 560V"
en-18 4022-D018396 Revision: 07
Page 19
TPM
+
- C hap ter 9.4.11 "Motor data, TPM+ power 560V, i = 4 – 35"
- Chapter 9.4.12 "Motor data, TPM
Select the appropriate product size of the desired servo controller in regard to the application
data.
+
power 560V, i = 40 – 100"
Startup and operation
Revision: 07 4022-D018396 en-19
Page 20
Maintenance and disposal TPM
7 Maintenance and disposal
Read the general safety instructions before beginning work (see Chapter 2.7 "General safety
instructions").
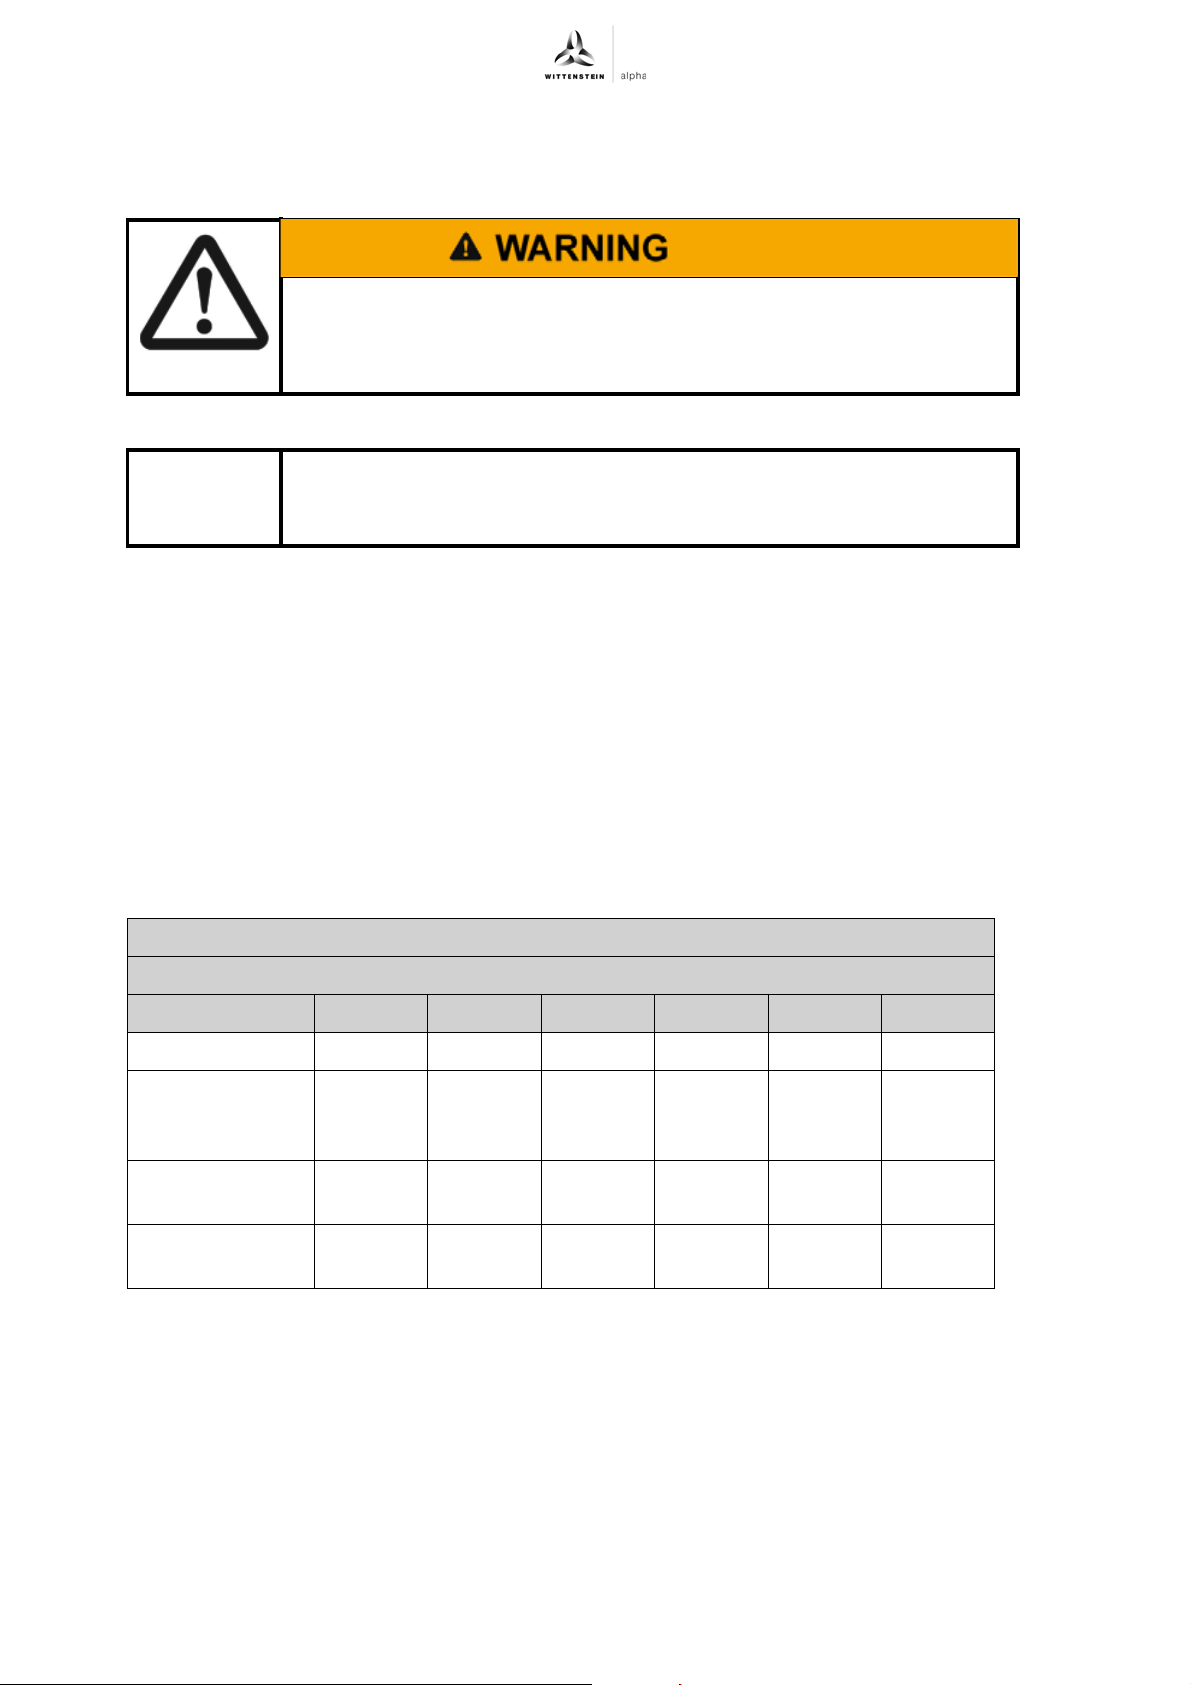
The permanent magnets of the rotor send a strong magnetic field,
which becomes active during the disassembling of the servo actuator.
Observe the general safety instructions (e.g. for pacemaker patients) for
working in strong magnetic fields.
7.1 Maintenance work
The partial or complete disassembly of the actuator into its individual
parts for maintenance or repair work is not permissible.
In case of a malfunction or failure, please contact Customer Service.
7.1.1 Refreshment of holding brake
The holding torques of the holding brakes used in the actuators are influenced by various factors,
e.g. oxidation of abraded particles, flattening of friction surfaces due to frequent application of the
brakes in the same position or air gap changes due to wear. This can lead to a tolerance in the
holding torque of - 50 % to + 100 %.
The specified holding torques apply under optimal conditions, without damaging influences. The
deterioration of the holding torque can be reduced by refreshing the brakes periodically.
For critical applications we recommend dimensioning for an adequately large holding torque to take
account of these factors. Our internal technical service would be glad to help you with the
appropriate dimensioning.
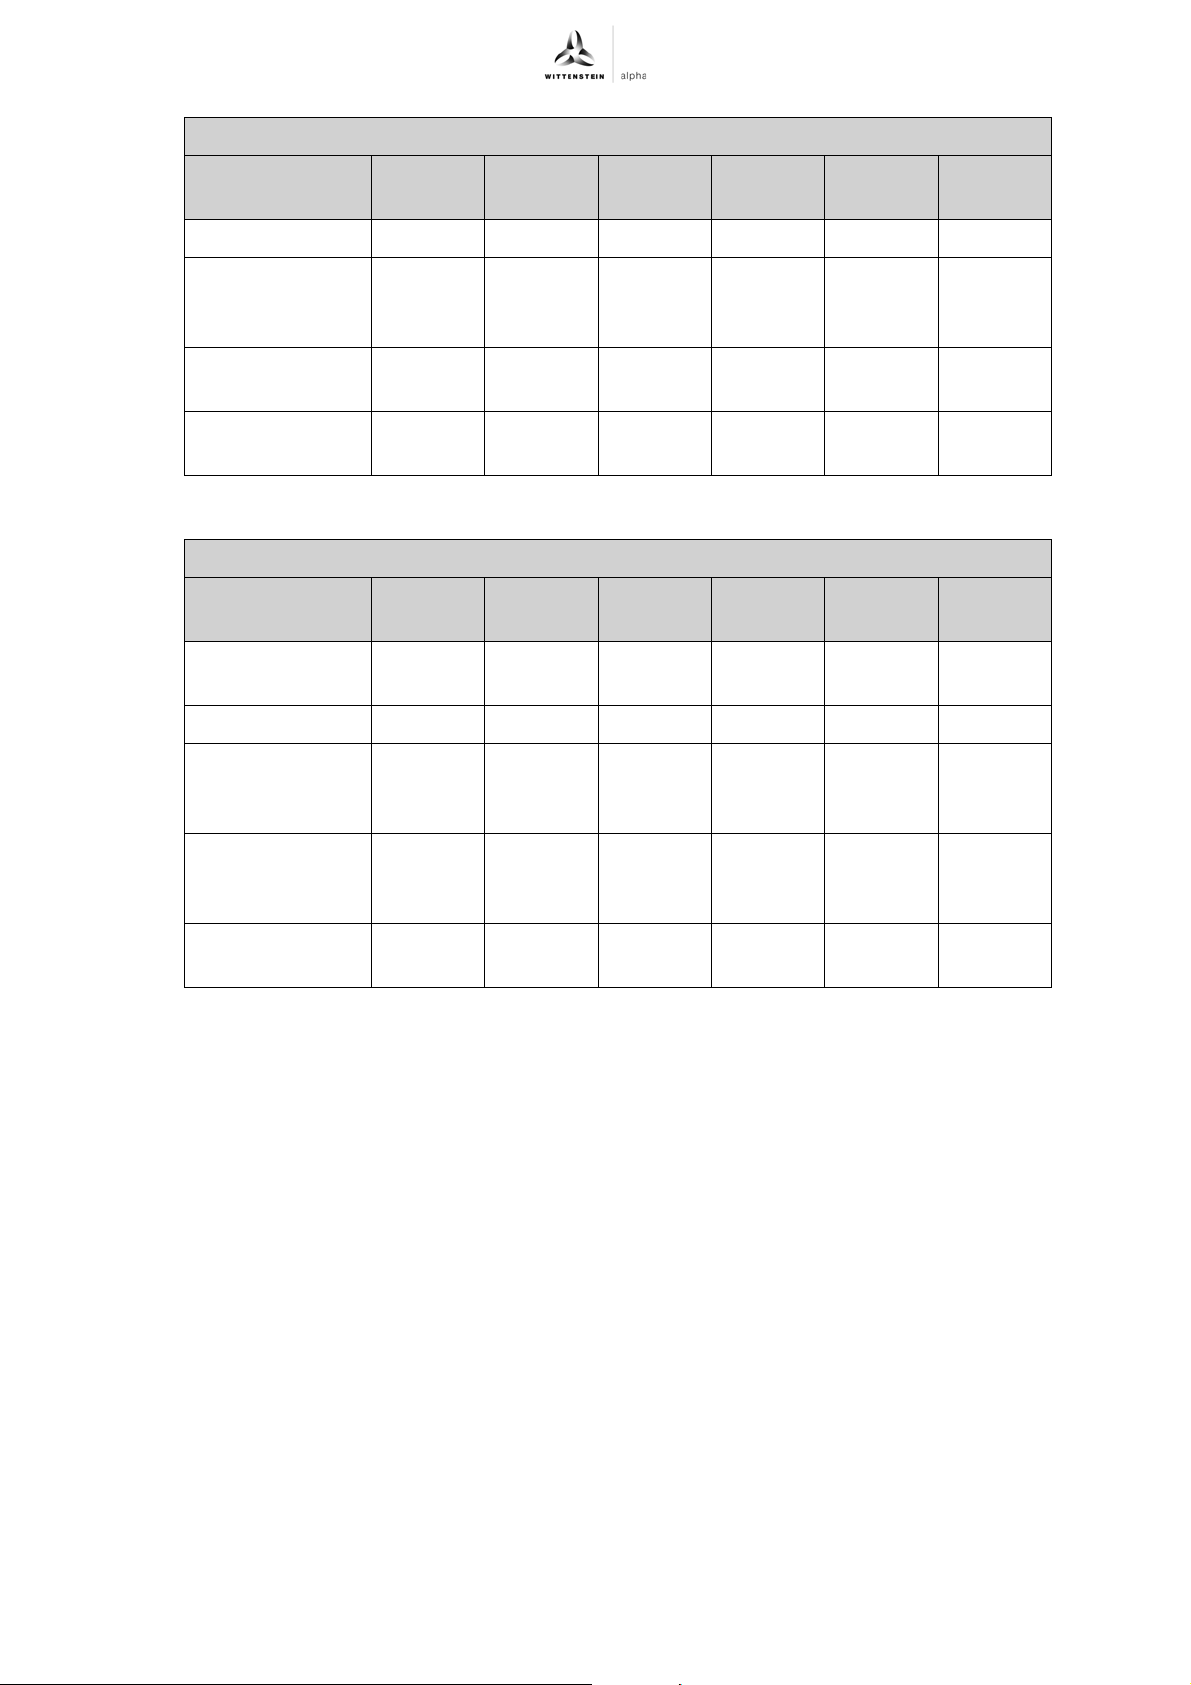
A maintenance interval of 4 weeks is recommended for common industrial applications.
For your dimensioning, observe the effective torques during running-in.
+
Recommended brake refreshment cycle, TPM+
For TPM+ dynamic
Unit TPM 004 TPM 010 TPM 025 TPM 050 TPM 110
Slipping speed rpm 200 200 100 100 100
Duration for
sec 0.5 0.5 0.5 0.5 0.5
brake de-
energized
Duration for
sec 0.5 0.5 0.5 0.5 0.5
brake energized
Number of
–33555
cycles
Tbl-5: TPM+ dynamic
en-20 4022-D018396 Revision: 07
Page 21
TPM
+
Maintenance and disposal
For TPM+ power
Unit TPMP
004
TPMP
010
TPMP
025
TPMP
050
TPMP
110
Slipping speed rpm 200 100 100 100 25
Duration for
sec 0.5 0.5 0.5 0.5 0.5
brake de-
energized
Duration for
sec 0.5 0.5 0.5 0.5 0.5
brake energized
Number of
–35555
cycles
Tbl-6: TPM+ power
For TPM+ high torque
Unit TPMA
004
TPMA
010
TPMA
025
TPMA
050
TPMA
110
i=22–88 i=110–
220
Slipping speed rpm 100 100 100 25 100
Duration for
brake de-
energized
Duration for
brake de-
energized
Number of
cycles
7.1.2 Visual inspection
Check the entire servo actuator and all cables for exterior damage.
The radial shaft seals are subject to wear. Therefore, also check the servo actuator for
leakage during each visual inspection (lubricant leaks).
Y ou can find more general information on radial shaf t seals on our partner's Internet site at
http://www.simrit.de.
Check the mounting position, so that no foreign medium (e.g. oil) has collected on the
output flange.
Check whether the safety signs (see Chapter 2.8 "Safety signs") and the type plate (see
Chapter 3.1 "Identification plate") are mounted and legible.
sec 0.5 0.5 0.5 0.5 0.5
sec 0.5 0.5 0.5 0.5 0.5
–55555
Tbl-7: TPM+ high torque
7.1.3 Checking the tightening torques
Check the tightening torque of the fastening screws on the servo actuator housing and at the
output flange.
The prescribed tightening torques can be found in Chapter 9.1 "Specifications o n mounting
onto a machine", Tables "Tbl-11" and "Tbl-12", and in Chapter 9.2 "Specifications on
mounting on the gear output side", Tables "Tbl-13", "Tbl-14" and "Tbl-15".
If, while checking the tightening torque, you discover that a screw can be further tightened,
follow the instructions in "Remounting the screw".
Revision: 07 4022-D018396 en-21
Page 22
Maintenance and disposal TPM
Remounting the screw
Make sure that it is possible to remount the screw on the gearhead
without damaging the entire machine.
Loosen the screw.
Remove the glue residue from the threaded bore and the screw.
De-grease the screw.
Coat the screw with a threadlocker (e.g. Loctite
Screw in the screw and tighten it with the prescribed tightening torque.
7.1.4 Cleaning
Pressurized air can damage the servo actuator seals.
Do not use pressurized air to clean the servo actuator.
Clean the servo actuator using a clean, lint-free cloth.
If necessary, use a suitable fat dissolving but non-aggressive cleaning agent.
®
243).
+
7.2 Startup after maintenance work
Clean the outside of the servo actuator.
Attach all safety devices.
Do a trial run before releasing the servo actuator again for operation.
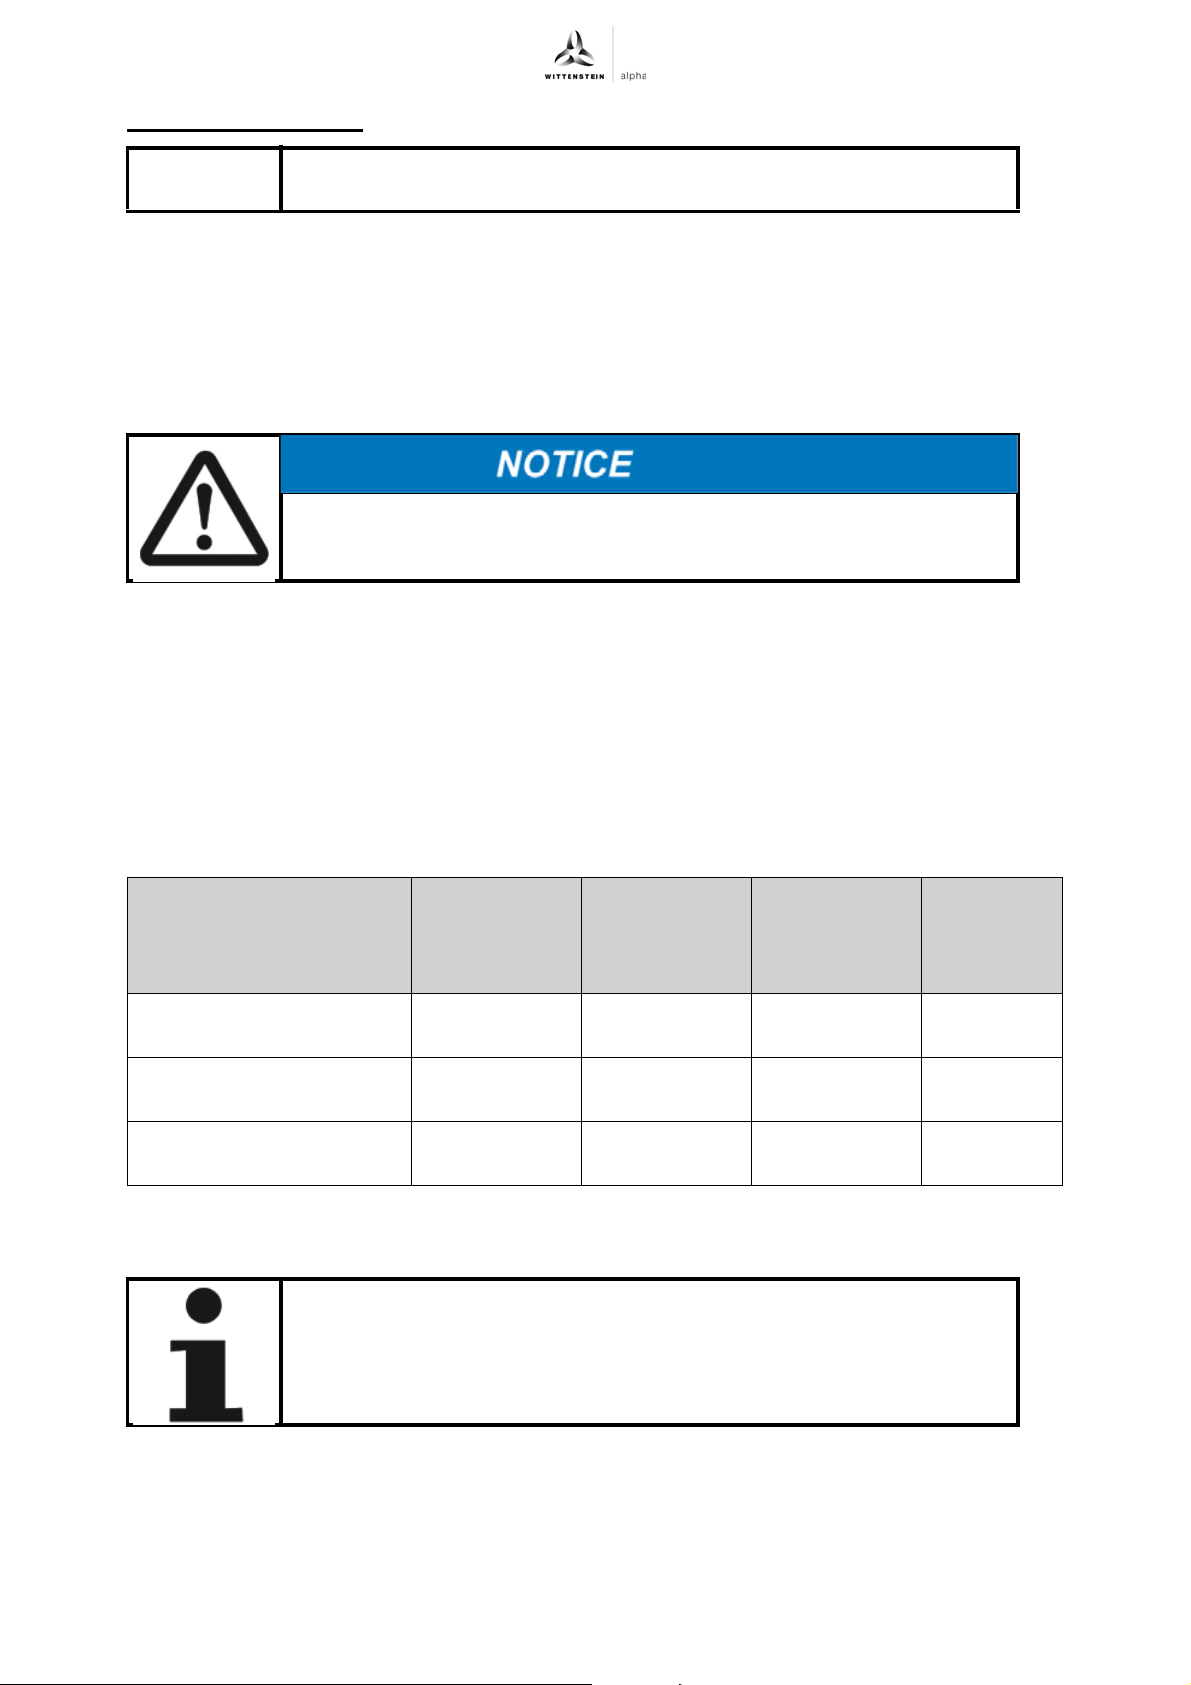
7.3 Maintenance schedule
Maintenance work At startup After 500
Refreshment of holding
brake
Visual inspection and
cleaning
Checking the tightening
torques
7.4 Information on the lubricant used
Every 4 weeks Yearly
operating
hours or 3
months
X
XX X
XX X
Tbl-8: Maintenance schedule
All servo actuators are permanently lubricated by the manufacturer with
synthetic gear oil (polyglycols) of viscosity class ISO VG100, ISO VG220 or
with a high-performance lubricant (see type plate). All bearings are
lubricated for life at the factory.
en-22 4022-D018396 Revision: 07
Page 23
TPM
+
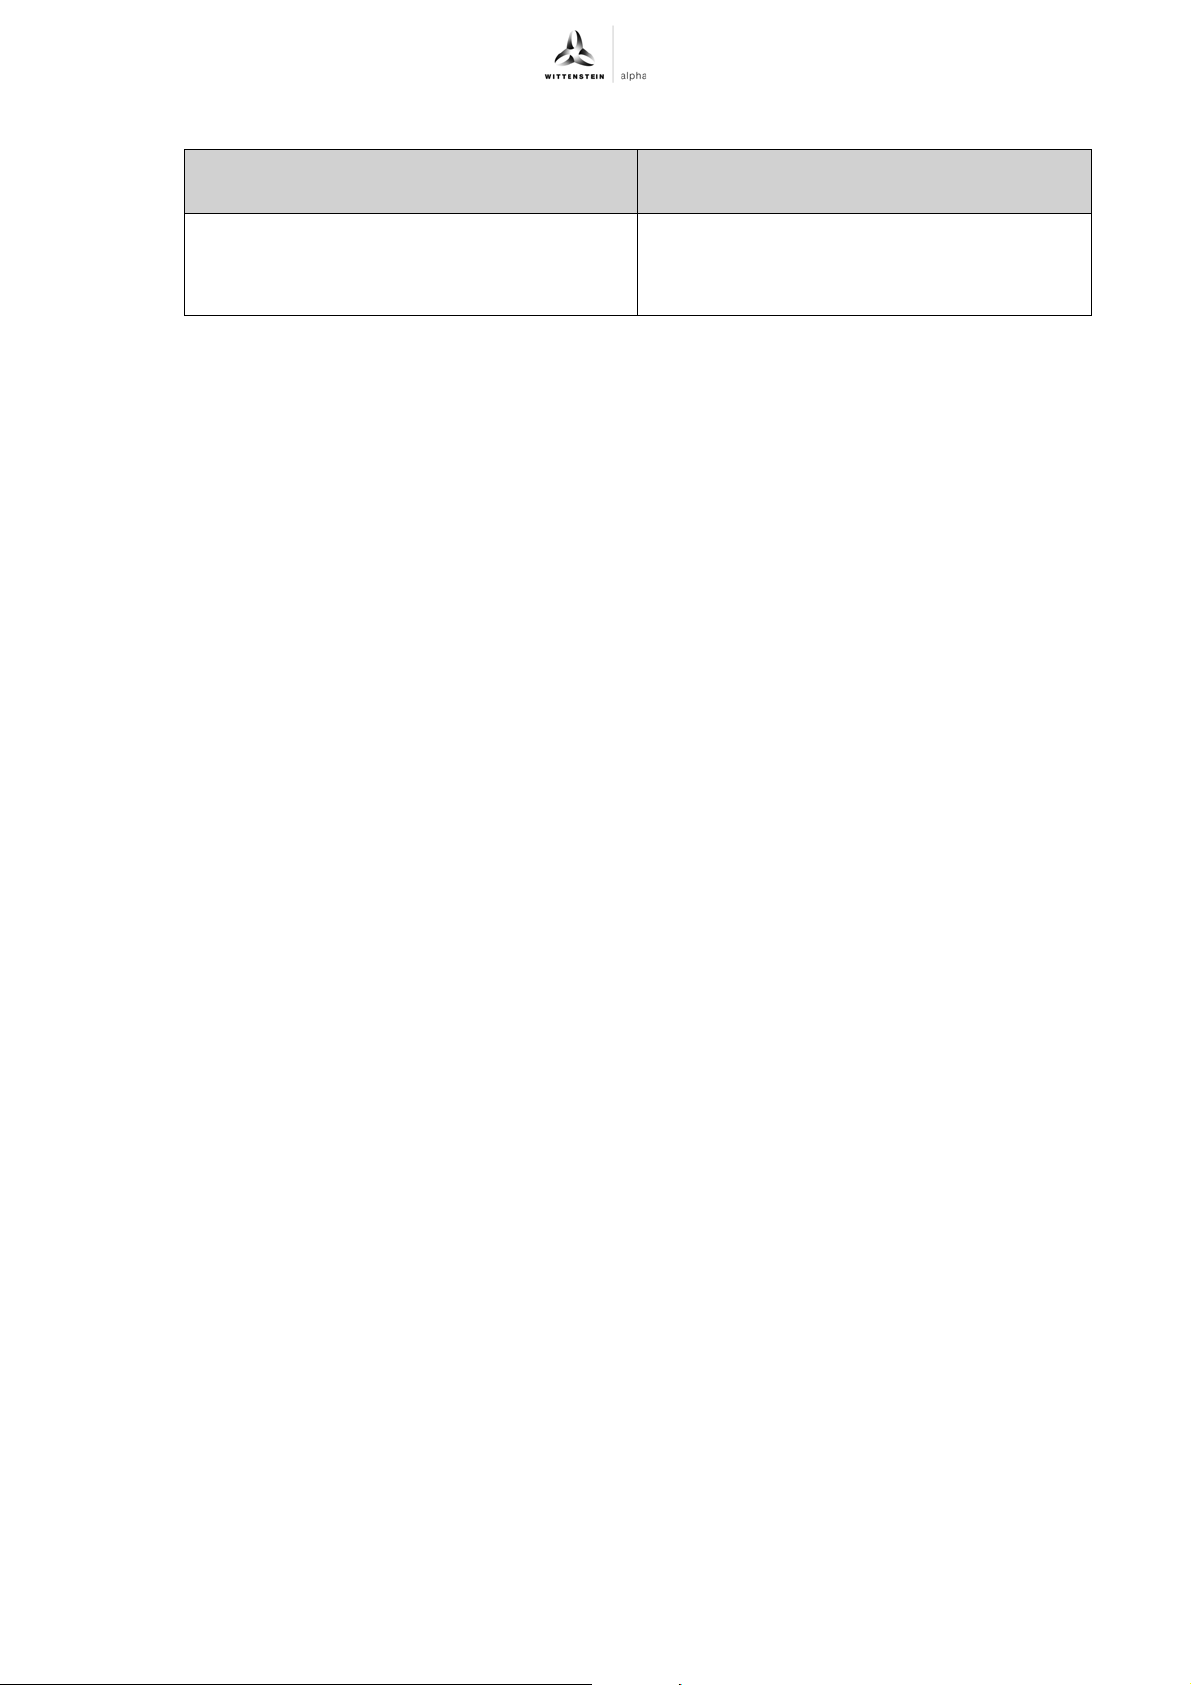
The manufacturer listed below will provide any further information on the lubricants:
Standard lubricants Lubricants for the food industry (NSF-H1
Maintenance and disposal
registered)
Castrol Industrie GmbH, Mönchengladbach
7.5 Disposal
Consult our Customer Service Department for supplementary information on disassembly and
disposal of the servo actuator.
Dispose of the servo actuator at the recycling sites intended for this purpose.
Observe the locally valid regulations for disposals.
Tel.: + 49 2161 909-30
www.castrol.com
Klüber Lubrication München KG, Munich
Tel.: + 49 89 7876–0
www.klueber.com
Tbl-9: Lubricant manufacturers
Revision: 07 4022-D018396 en-23
Page 24
Malfunctions TPM
8 Malfunctions
Changed operational behavior can be an indication of existing damage
to the servo actuator, or cause damage to the servo actuator.
Do not put the servo actuator back into operation until the cause of the
malfunction has been rectified.
Rectifying of malfunctions may only be done by specially trained
technicians.
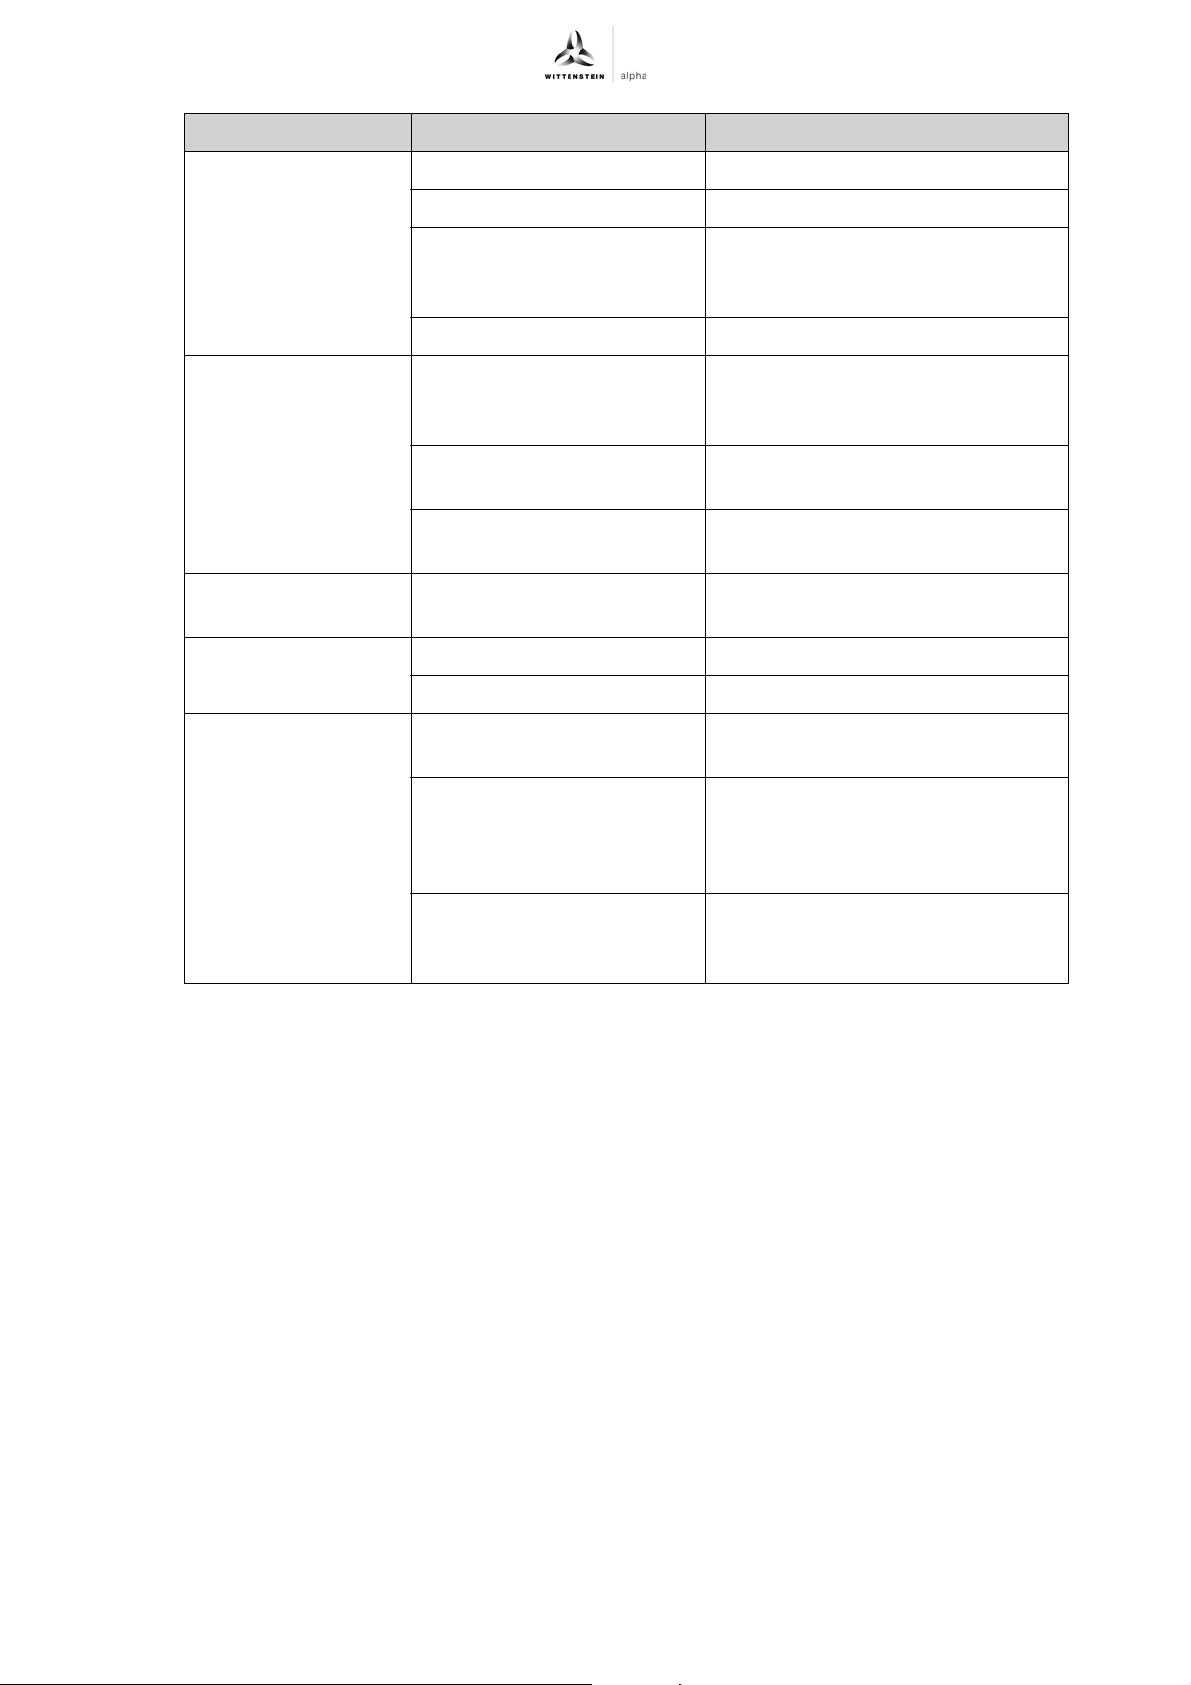
To facilitate troubleshooting and the optimization of controller settings, it is
useful to record the current over a full cycle (a servo controller function) and
make it available as a file.
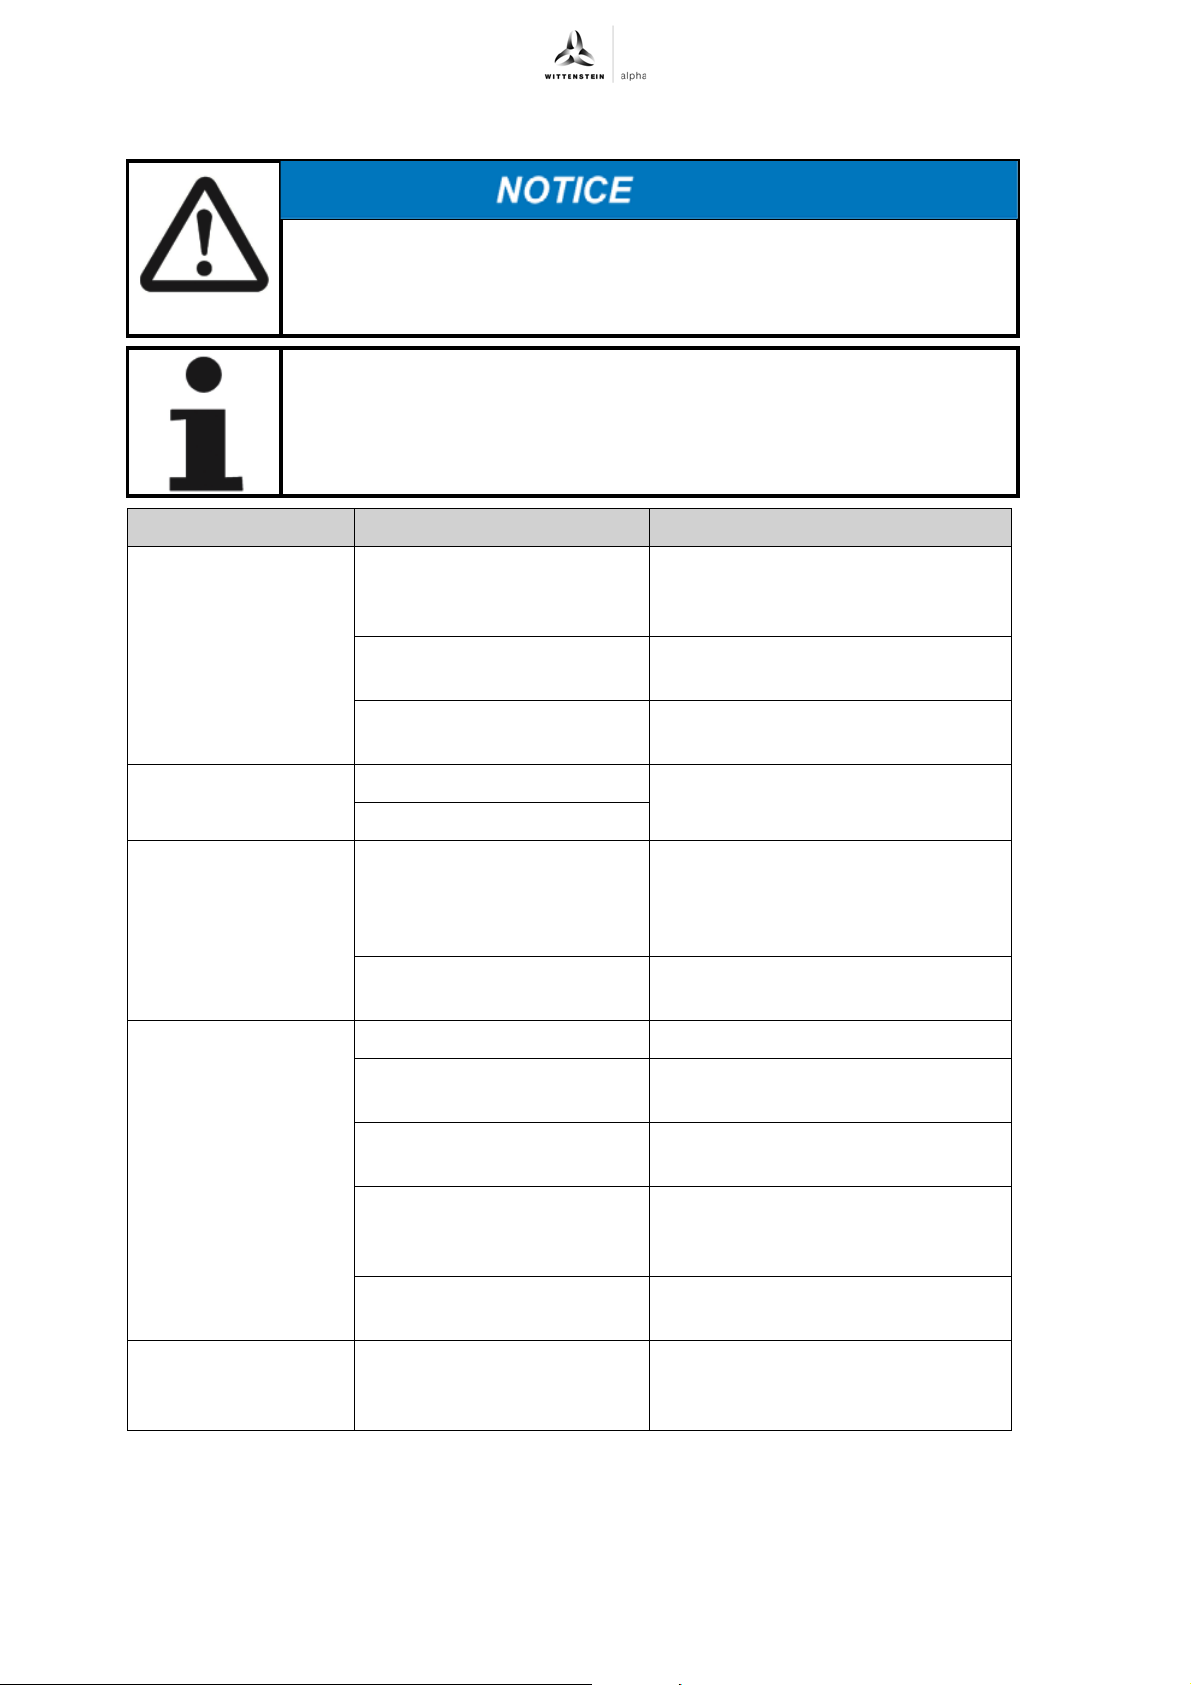
Fault Possible cause Solution
+
Increased operating
temperature
Increased operating
noises
Loss of lubricant Lubricant quantity too high Wipe off discharged lubricant and
Motor does not start Power supply interrupted Check the connections
Selected construction too
weak for task, nominal
operating exceeded.
Motor is heating the
gearhead.
Ambient temperature too
high.
Damaged bearings Consult our Customer Service
Damaged gear teeth
Seals not tight Consult our Customer Service
Wiring of motor and / or
encoder not correct
Blown fuse Check for errors and replace the
Check the technical specifications.
Check the controller's settings.
Ensure adequate cooling.
department.
continue to watch the gearhead.
Lubricant discharge should stop
after a short time.
department.
Check the wiring of the motor
phases and the motor encoder
fuse
Incorrect controller
parameters
Motor protection has been
triggered
Wrong direction of
rotation
en-24 4022-D018396 Revision: 07
Wrong set value
specification for the servo
controller
Check that the motor parameters
are suitable for the implemented
servo actuator
Check for errors. Check whether the
motor protection setting is correct.
Check servo controller/converter.
Check the set value specifications
and the polarities
Page 25
TPM
+
Fault Possible cause Solution
Malfunctions
Motor is droning and
has a high power
consumption
Brake does not
release
Holding brake slips Stopping torque of the brake
Acceleration times
are not met
Position error Shielding of the encoder line
Drive is blocked Check the drive
Error in the encoder line Check the encoder line
Incorrect controller
parameters
Brake does not release (see fault "Brake does not release")
Voltage drop along the
supply line > 10%
Incorrect brake connection Check the connection for correct
Short circuit in the coil or at
body of brake coil
exceeded
Load is too high Check the dimensioning
Power limiting active Check the controller parameters
insufficient
Check that the motor parameters
are suitable for the implemented
servo actuator
Ensure that the supply voltage is
correct. Check the cable cross-
section.
polarity and voltage
Consult our Customer Service
department.
Check the construction plan. Carry
out a refreshment.
Inspect the shielding of the
connection cables
Disturbing pulse from the
brake, protective circuit of
the brake missing or
defective
Mechanical coupling
between the motor shaft and
encoder defective
Tbl-10: Malfunctions
Check the protective circuit (e.g.
Varistor) of the brake on the
converter
Consult our Customer Service
department.
Revision: 07 4022-D018396 en-25
Page 26
Appendix TPM
9 Appendix
In case of questions on the special applications, please contact WITTENSTEIN alpha GmbH.
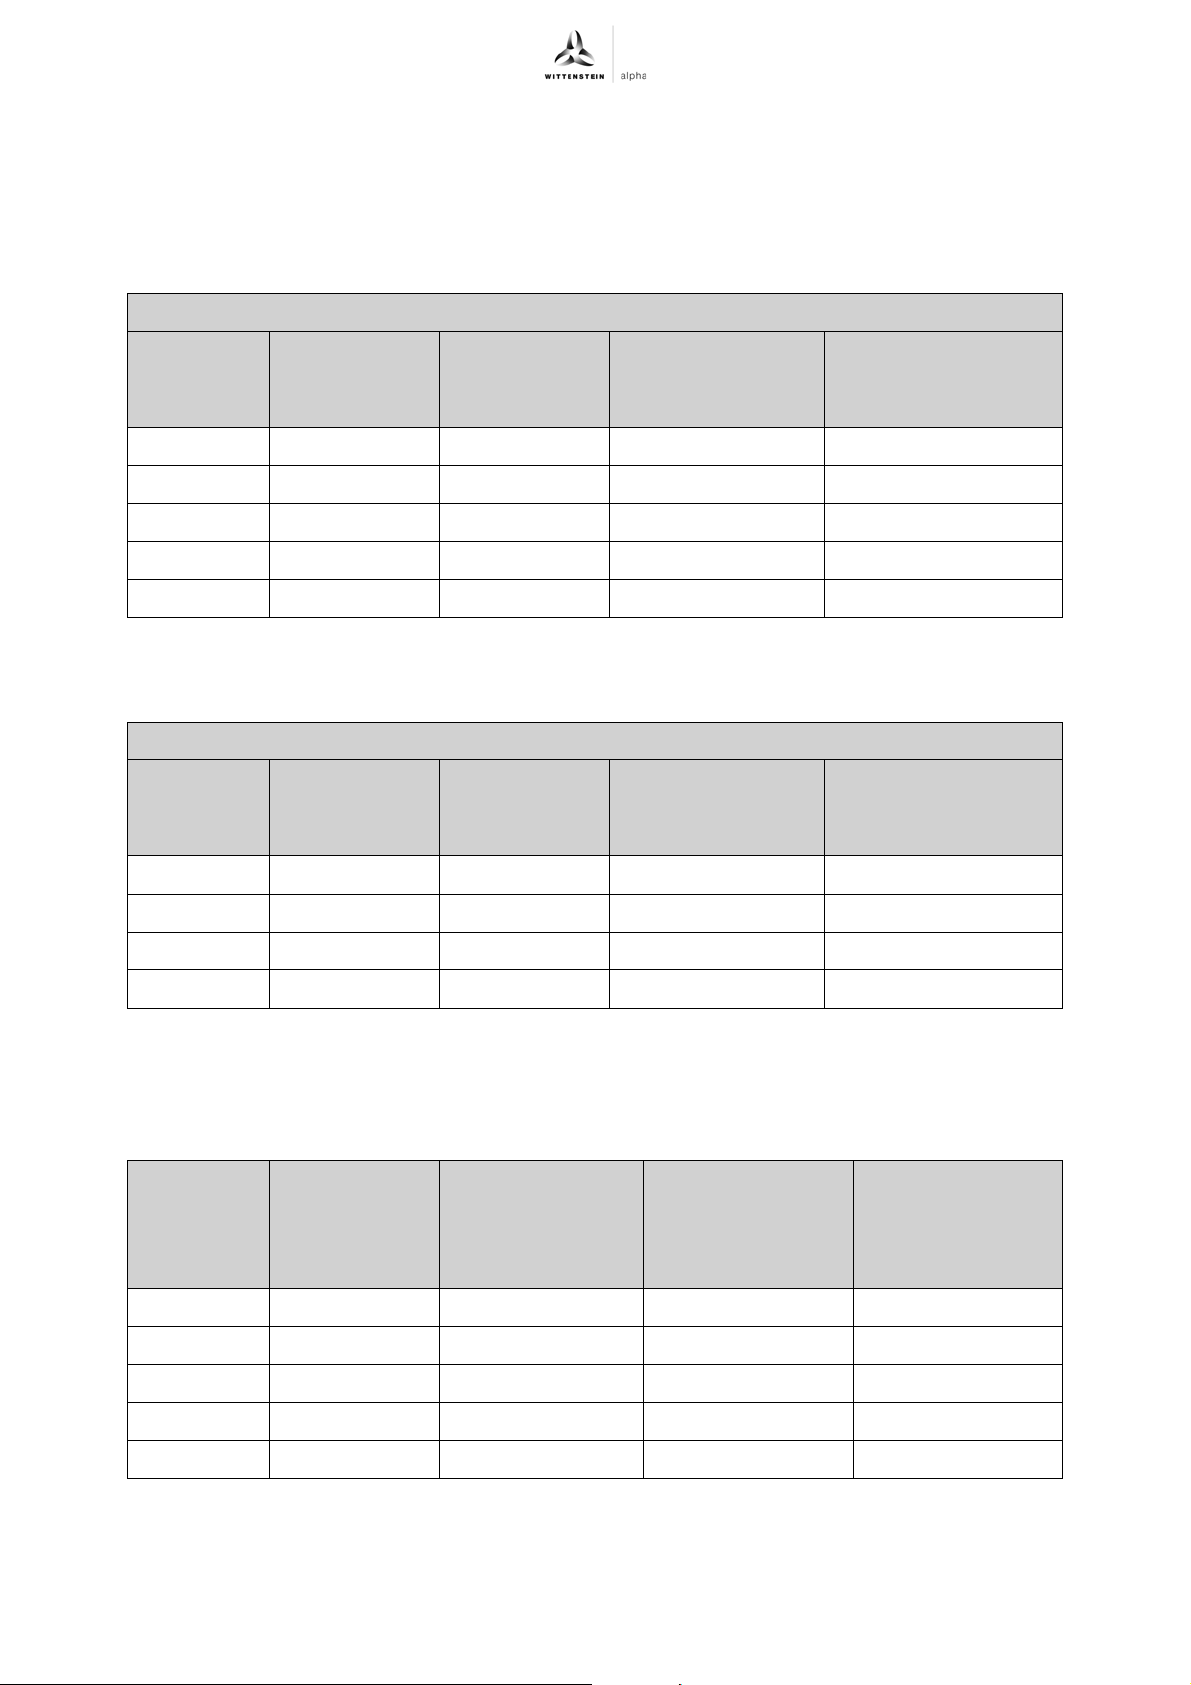
9.1 Specifications on mounting onto a machine
+
9.1.1 Specifications for the TPM
Through-holes in the servo actuator housing TPM+ dynamic/TPM+ power
dynamic/TPM+ power version
+
Type/Size Bore Ø
[mm]
+
004 79 8 x 4.5 M4 / 12.9 4.55
TPM
+
TPM
010 109 8 x 5.5 M5 / 12.9 9.0
+
025 135 8 x 5.5 M5 / 12.9 9.0
TPM
+
TPM
050 168 12 x 6.6 M6 / 12.9 15.4
+
TPM
110 233 12 x 9.0 M8 / 12.9 37.3
Tbl-11: Specifications on mounting onto a machine, TPM+ dynamic / TPM+ power
9.1.2 Specifications for the TPM
Through-holes in the servo actuator housing TPM+ high torque
Type/Size Holecircle Ø
[mm]
+
010 109 16 x 5.5 M5 / 12.9 9.0
TPM
+
TPM
025 135 16 x 5.5 M5 / 12.9 9.0
+
TPM
050 168 24 x 6.6 M6 / 12.9 15.4
+
110 233 24 x 9.0 M8 / 12.9 37.3
TPM
Quantity x
diameter
[ ] x [mm]
+
high torque version
Quantity x
diameter
[ ] x [mm]
For screw size /
property class
For screw size /
property class
Tightening torque
[Nm]
Tightening torque
[Nm]
Tbl-12: Specifications on mounting onto a machine, TPM+ high torque
9.2 Specifications on mounting on the gear output side
+
9.2.1 Thread in output flange, TPM
Type/Size Indexbore Øx
depth
dynamic
Bore Ø
[mm]
[mm] x [mm]
+
TPM
004 5 H 7 x 8 31.5 7 x M5 x 7 9.0
+
TPM
010 6 H 7 x 7 50.0 7 x M6 x 10 15.4
+
025 6 H 7 x 7 63.0 11 x M6 x 12 15.4
TPM
+
TPM
050 8 H 7 x 10 80.0 11 x M8 x 15 37.3
+
TPM
110 10 H 7 x 12 125.0 11 x M10 x 20 73.4
Tbl-13: Thread in output flange (ISO9409), TPM+ dynamic
Quantity x Thread
x Depth
[ ] x [mm] x [mm]
Tightening torque
[Nm]
Property class
12.9
en-26 4022-D018396 Revision: 07
Page 27
+
TPM
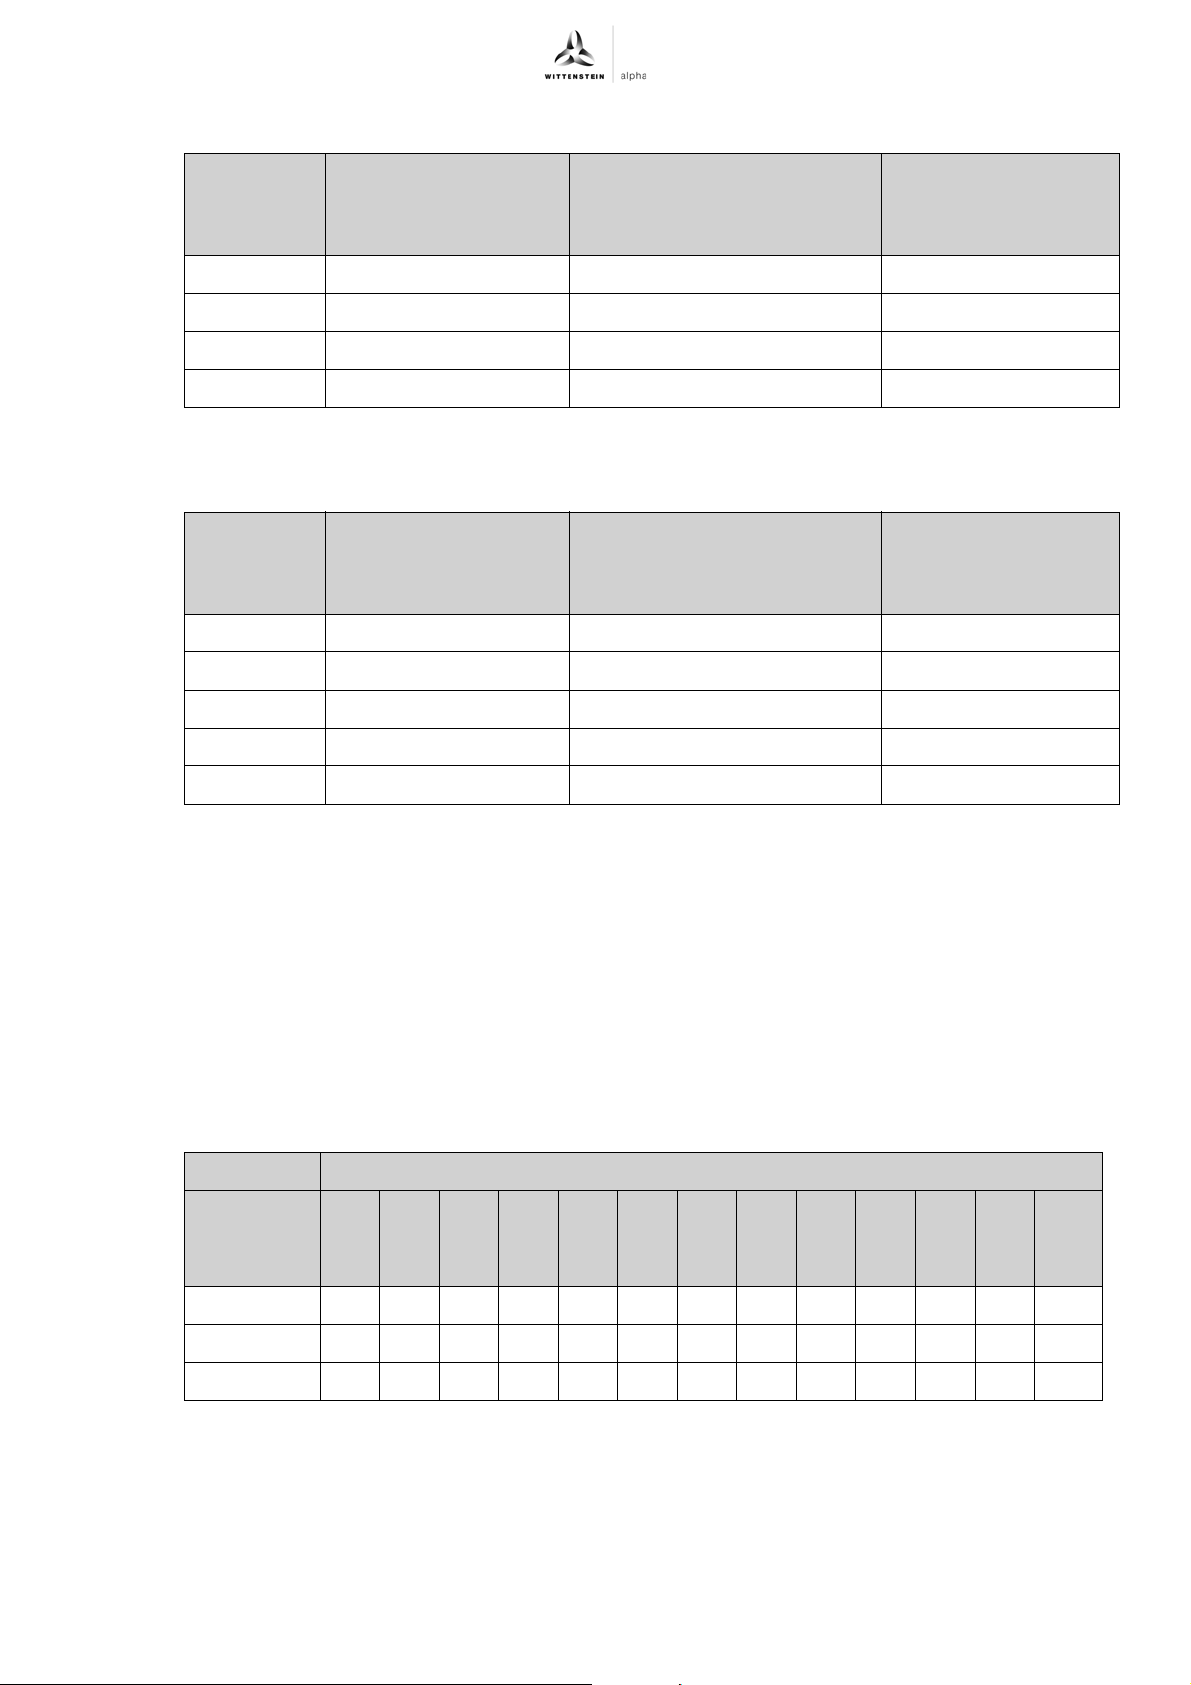
9.2.2 Thread in output flange, TPM+ high torque
Appendix
Type/Size Bore Ø
[mm]
+
TPM
010 50.0 12 x M6 x 10 15.4
+
025 63.0 12 x M8 x 12 37.3
TPM
+
TPM
050 80.0 12 x M10 x 15 73.4
+
TPM
110 125.0 12 x M12 x 19 126.0
Tbl-14: Thread in output flange (ISO9409), TPM+ high torque
9.2.3 Thread in output flange, TPM
Type/Size Bore Ø
[mm]
+
TPM
004 31.5 8 x M5 x 7 9.0
+
010 50.0 8 x M6 x 10 15.4
TPM
+
TPM
025 63.0 12 x M6 x 12 15.4
+
TPM
050 80.0 12 x M8 x 15 37.3
+
110 125.0 12 x M10 x 20 73.4
TPM
+
power
Quantity x Thread x Depth
[ ] x [mm] x [mm]
Quantity x Thread x Depth
[ ] x [mm] x [mm]
Tightening torque
[Nm]
Property class 12.9
Tightening torque
[Nm]
Property class 12.9
Tbl-15: Thread in output flange (ISO9409), TPM+ power
9.3 Tightening torques for common thread sizes in general mechanical engineering
The specified tightening torques for headless screws and nuts are calculated values and are based
on the following conditions:
- Calculation in accordance with VDI 2230 (February 2003 version)
- Friction value for thread and contact surfaces µ=0.10
- Exploitation of the yield stress 90%
- Torque tools type II classes A and D in accordance with ISO 6789
The settings are values rounded to usual commercial scale gradations or setting possibilities.
Set these values precisely on the scale.
Tightening torque [Nm] with thread
Property
M3 M4 M5 M6 M8 M10 M12 M14 M16 M18 M20 M22 M24
class
Screw / nut
8.8 / 8 1.15 2.64 5.2 9.0 21.5 42.5 73.5 118 180 258 362 495 625
10.9 / 10 1.68 3.88 7.6 13.2 32.0 62.5 108 173 264 368 520 700 890
12.9 / 12 1.97 4.55 9.0 15.4 37.5 73.5 126 202 310 430 605 820 1040
Tbl-16: Tightening torques for headless screws and nuts
Revision: 07 4022-D018396 en-27
Page 28
Appendix TPM
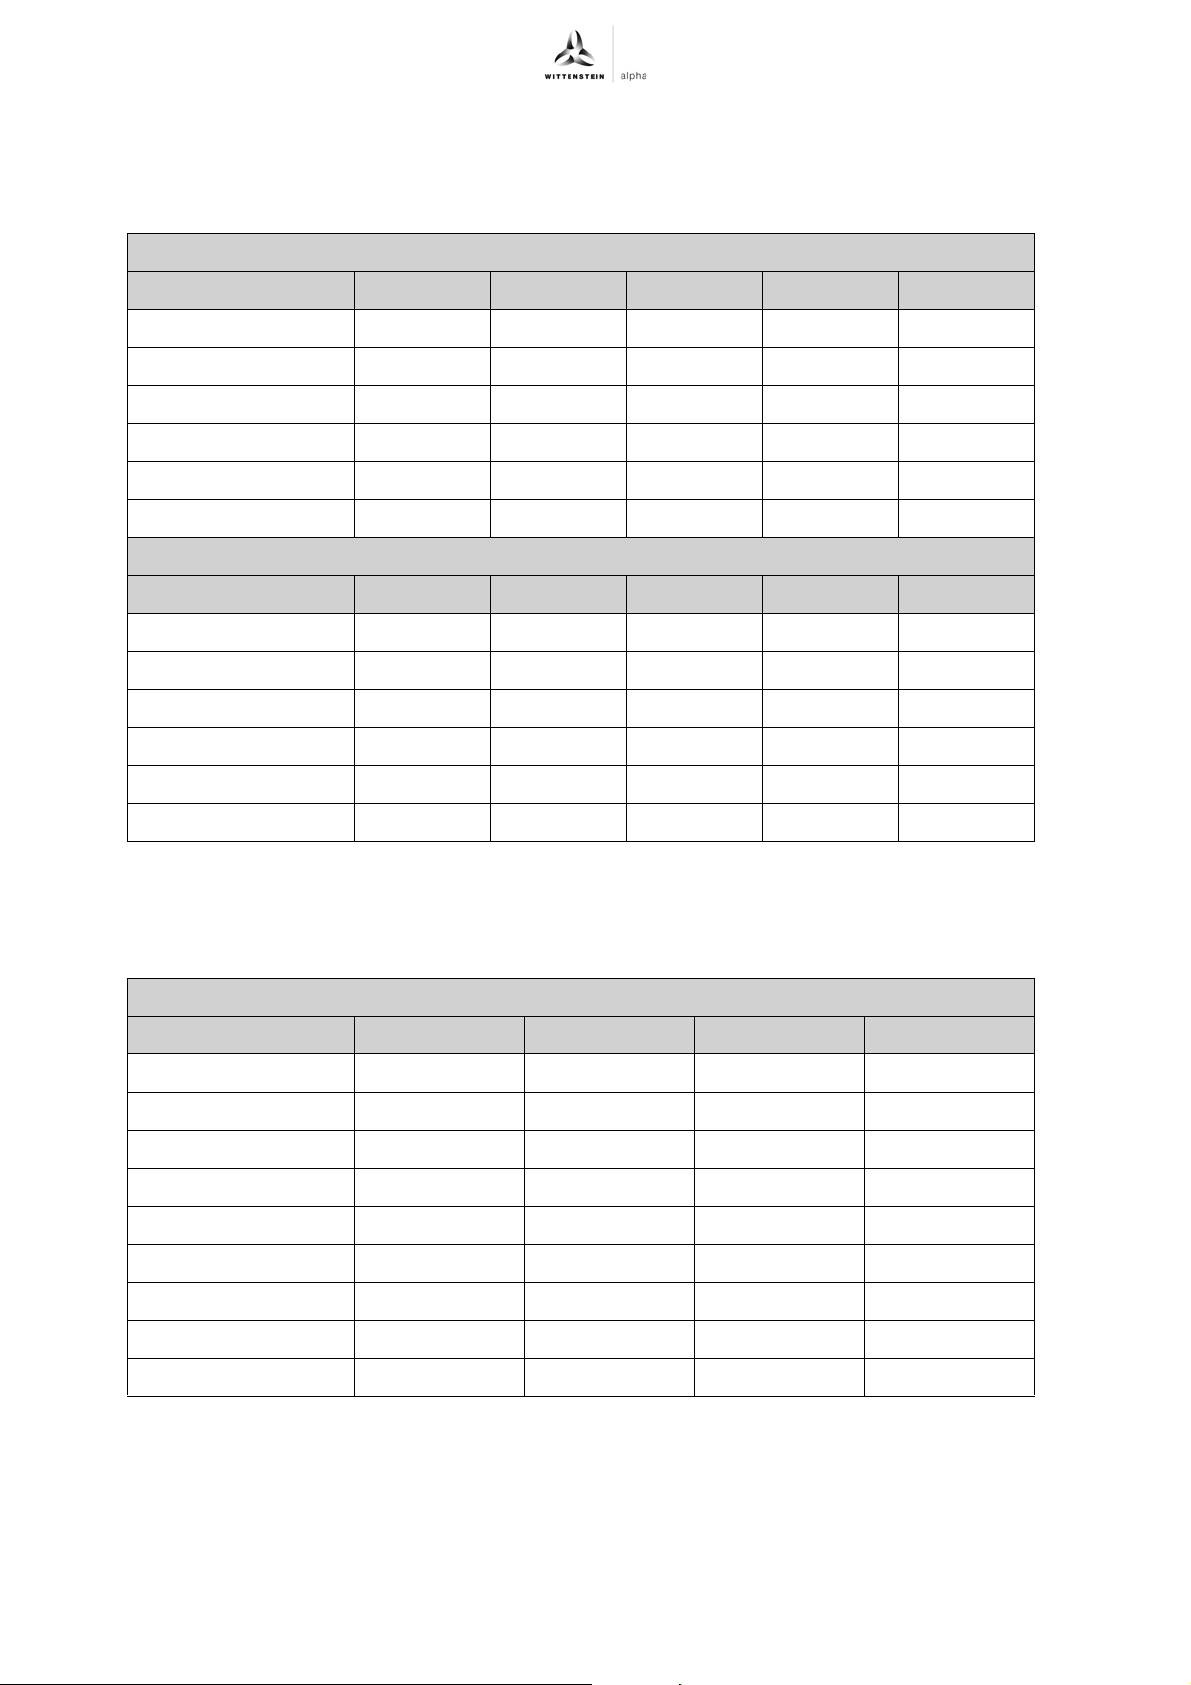
9.4 Technical specifications
+
9.4.1 Moments of inertia TPM
(Total moment of inertia in respect to the motor shaft)
Moments of inertia without brake with resolver [kgcm]
Ratio TPM+ 004 TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
16 0.21 0.32 2.16 9.07 13.14
21 0.2 0.32 2.16 9.07 13.14
31 0.2 0.32 2.17 8.94 12.84
61 0.12 0.17 0.77 2.51 8.89
64 0.11 0.17 0.76 2.49 8.83
91 0.12 0.17 0.76 2.49 8.83
Moments of inertia with brake with resolver [kgcm]
Ratio TPM+ 004 TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
16 0.23 0.34 2.35 10.07 14.14
dynamic
+
21 0.23 0.34 2.35 10.07 14.14
31 0.22 0.34 2.36 9.93 13.84
61 0.14 0.19 0.96 3.51 9.88
64 0.13 0.19 0.95 3.49 9.83
91 0.14 0.19 0.95 3.49 9.83
9.4.2 Moments of inertia TPM
(Total moment of inertia in respect to the motor shaft)
Moments of inertia without brake with resolver [kgcm]
Ratio TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
22 2.06 9.01 23.8 220.37
27.5 2.03 8.83 23.35 218.91
38.5 2.01 8.74 22.99 217.63
55 1.99 8.69 22.81 216.94
66 – 2.03 9.23 111.82
Tbl-17: Moments of inertia TPM+ dynamic
+
high torque
88 2.01 1.96 9.04 108.24
110 2.0 1.93 8.84 22.86
154 0.68 1.91 8.74 22.48
220 0.67 1.89 8.69 22.25
en-28 4022-D018396 Revision: 07
Page 29
+
TPM
Moments of inertia with brake with resolver [kgcm]
Ratio TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
22 2.25 10.0 25.6 236.87
27.5 2.22 9.83 25.15 235.41
38.5 2.2 9.74 24.79 234.13
55 2.18 9.69 24.61 233.44
66 – 2.22 10.22 128.82
88 2.2 2.15 10.03 125.24
110 2.19 2.12 9.83 24.66
154 0.87 2.1 9.74 24.28
220 0.86 2.08 9.69 24.05
Tbl-18: Moments of inertia TPM+ high torque
9.4.3 Moments of inertia TPM+ power
(Total moment of inertia in respect to the motor shaft)
Appendix
Moments of inertia without brake with resolver [kgcm]
Ratio TPM+ 004 TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
4 0.39 2.38 9.98 26.42 141.73
5 0.36 2.22 9.5 24.8 131.91
7 0.33 2.08 9.07 23.34 123
10 0.31 2 8.84 22.54 118.12
16 0.32 2.02 8.94 23.07 116.99
20 0.31 1.99 8.83 22.61 116.7
25 0.31 1.98 8.81 22.55 116.3
28 0.31 1.96 8.72 22.2 115.05
35 0.31 1.96 8.71 22.17 114.85
40 0.16 0.72 2.48 6.3 60.23
50 0.16 0.72 2.48 6.28 60.13
70 0.16 0.72 2.48 6.27 60.04
100 0.16 0.72 2.47 6.26 59.99
Moments of inertia with brake with resolver [kgcm]
Ratio TPM+ 004 TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
4 0.41 2.57 10.98 28.22 158.73
5 0.38 2.41 10.5 26.6 148.91
7 0.35 2.27 10.07 25.14 140
10 0.34 2.19 9.84 24.34 135.12
16 0.34 2.21 9.94 24.87 133.99
20 0.34 2.18 9.82 24.41 133.7
25 0.34 2.17 9.8 24.35 133.3
Revision: 07 4022-D018396 en-29
Page 30
Appendix TPM
Moments of inertia with brake with resolver [kgcm]
Ratio TPM+ 004 TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
28 0.33 2.15 9.72 24 132.05
35 0.33 2.14 9.71 23.97 131.85
40 0.18 0.91 3.48 8.1 77.23
50 0.18 0.91 3.48 8.08 77.13
70 0.18 0.91 3.47 8.07 77.04
100 0.18 0.91 3.47 8.06 76.99
Tbl-19: Moments of inertia TPM+ power
9.4.4 Motor data, TPM+ dynamic 320V, i = 16 – 31
General data
+
Unit TPM+
004
TPM+
010
TPM+
025
TPM+
050
TPM+
110
Stator length mm 30 30 45 60 75
Pole pair number p p 44666
Maximum torque T
Maximum current I
*
max
max
Nm 2 3.8 12.1 28.9 43.9
Aeff 5.5 9 29.4 70 70
Maximum speed rpm 6000 6000 6000 5000 3700
Continuous stall
torque T
0
Continuous stall
current I
Torque constant K
Voltage constant K
*
0
t
e
Winding resistance at
Nm 0.72 1.2 5.5 13.49 16.42
Aeff 1.9 2.25 9.9 23.7 16.7
Nm/Aeff 0.4 0.56 0.56 0.58 1
Veff/krpm 24.4 34.1 34.3 35.4 61
Ohm 9.4 7.1 0.73 0.13 0.32
20 °C terminalterminal
Winding inductance
mH 11.1 7.33 2 1 2.4
terminal-terminal
Electrical time
constant T
e
Max. winding
temperature θ
max
msec 1.2 1.1 2.7 6.7 7.4
°C 155 155 155 155 155
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
®
You can determine the design for each case with our design software cymex
Tbl-20: Motor data, TPM+ dynamic 320V, i = 16 – 31
en-30 4022-D018396 Revision: 07
.
Page 31
+
TPM
9.4.5 Motor data, TPM+ dynamic 320V, i = 61 – 91
General data
Appendix
Unit TPM+
004
TPM+
010
TPM+
025
TPM+
050
TPM+
110
Stator length mm 15 15 15 15 60
Pole pair number p p 44666
Maximum torque T
Maximum current I
max
* Aeff 4.2 5.2 10.4 21 70
max
Nm 0.98 1.9 4.4 7.8 28.9
Maximum speed rpm 6000 6000 6000 5000 5000
Continuous stall torque
T
0
Continuous stall
current I
Torque constant K
Voltage constant K
*
0
t
e
Winding resistance at
Nm 0.36 0.67 1.86 3.59 13.49
Aeff 1.38 1.6 3.3 6.6 23.7
Nm/Aeff 0.27 0.45 0.59 0.56 0.58
Veff/krpm 16.3 27.6 35.4 33.9 35.4
Ohm 12.5 13.3 4.5 1.33 0.13
20 °C terminal-terminal
Winding inductance
mH 10 10 6.3 3.7 1
terminal-terminal
Electrical time constant
T
e
Max. winding
temperature θ
max
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
You can determine the design for each case with our design software cymex
9.4.6 Motor data, TPM
Ratio i 22 –110 154 –220 22 –55 66 –220
Stator length mm 45 15 60 45
Pole pair number p p6666
Maximum torque T
Maximum current I
Maximum speed rpm 4850 4850 4850 4850
msec 0.4 0.8 1.4 2.8 6.7
°C 155 155 155 155 155
Tbl-21: Motor data, TPM+ dynamic 320V, i = 61 – 91
+
high torque 320V
max
* Aeff 29.4 10.4 70.0 29.4
max
®
.
General data
Unit TPM+ 010 TPM+ 025
Nm 11.98 4.4 28.9 11.98
Continuous stall torque T
Continuous stall current I
Torque constant K
Voltage constant K
Revision: 07 4022-D018396 en-31
t
e
0
* Aeff 8.64 3.33 22.66 9.98
0
Nm 3.75 1.44 10.92 4.19
Nm/Aeff 0.48 0.47 0.56 0.48
Veff/krpm 29.0 28.4 34.2 29.0
Page 32
Appendix TPM
General data
Unit TPM+ 010 TPM+ 025
Ratio i 22 –110 154 –220 22 –55 66 –220
+
Winding resistance at 20 °C
terminal-terminal
Winding inductance
terminal-terminal
Electrical time constant T
e
Max. winding temperature
θ
max
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
You can determine the design for each case with our design software cymex
9.4.7 Motor data, TPM+ power 320V
Ratio i 4 –35 40 –100 4 –35 40 –100 4 –35 40 –100
Stator length mm 30 15 45 15 60 15
Ohm 0.81 5.23 0.16 0.81
mH 2.0 6.3 1.0 2.0
msec 2.5 1.2 6.4 2.5
°C 155 155 155 155
®
.
Tbl-22: Motor data, TPM+ high torque 320V
General data
Unit TPM+ 004 TPM+ 010 TPM+ 025
Pole pair number p p 446666
Maximum torque T
Maximum current I
max
max
Nm 3.8 1.9 12.1 4.4 28.9 7.8
* Aeff 9 5.2 29.4 10.4 70 21
Maximum speed rpm 6000 6000 6000 6000 6000 6000
Continuous stall torque
T
0
Continuous stall
current I
Torque constant K
Voltage constant K
*
0
t
e
Winding resistance at
Nm 1.25 0.66 4.5 1.38 11.68 3
Aeff 2.7 1.73 9.35 3.22 23.73 6.93
Nm/Aeff 0.56 0.45 0.56 0.59 0.58 0.56
Veff/krpm 34.1 27.6 34.3 35.4 35.4 33.9
Ohm 7.1 13.3 0.73 4.5 0.13 1.33
20 °C terminal-terminal
Winding inductance
mH 7.33 10 2 6.3 1 3.7
terminal-terminal
Electrical time constant
T
e
Max. winding
temperature θ
max
msec 1.1 0.8 2.7 1.4 6.7 2.8
°C 155 155 155 155 155 155
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
®
You can determine the design for each case with our design software cymex
.
Tbl-23: Motor data, TPM+ power 320V
en-32 4022-D018396 Revision: 07
Page 33
+
TPM
9.4.8 Motor data, TPM+ dynamic 560V, i = 16 – 31
General data
Appendix
Unit TPM+
004
TPM+
010
TPM+
025
TPM+
050
TPM+
110
Stator length mm 30 30 45 60 75
Pole pair number p p 44666
Maximum torque T
Maximum current I
max
* Aeff 3.2 5.2 17 40 70
max
Nm 2 3.8 12.1 28.9 43.9
Maximum speed rpm 6000 6000 6000 5000 5000
Continuous stall torque
T
0
Continuous stall
current I
Torque constant K
Voltage constant K
*
0
t
e
Winding resistance at
Nm 0.72 1.2 5.5 13.49 16.42
Aeff 1.1 1.3 5.7 13.7 16.7
Nm/Aeff 0.7 0.97 0.98 1 1
Veff/krpm 42.2 58.5 59.5 61 61
Ohm 28.2 21.3 2.2 0.45 0.32
20 °C terminal-terminal
Winding inductance
mH 33.3 22.8 6 3 2.4
terminal-terminal
Electrical time constant
T
e
Max. winding
temperature θ
max
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
You can determine the design for each case with our design software cymex
9.4.9 Motor data, TPM
Stator length mm 15 15 15 15 60
Pole pair number p p 44666
Maximum torque T
Maximum current I
Maximum speed rpm 6000 6000 6000 5000 5000
msec 1.2 1.1 2.7 6.7 7.4
°C 155 155 155 155 155
Tbl-24: Motor data, TPM+ dynamic 560V, i = 16 – 31
+
dynamic 560V, i = 61 – 91
Unit TPM+
max
* Aeff 2.4 3 6 12 40
max
Nm 0.98 1.9 4.4 7.8 28.9
General data
004
TPM+
010
TPM+
025
®
.
TPM+
050
TPM+
110
Continuous stall torque
T
0
Continuous stall
current I
Torque constant K
Voltage constant K
Revision: 07 4022-D018396 en-33
*
0
t
e
Nm 0.36 0.67 1.86 3.59 13.49
Aeff 0.8 0.9 1.9 3.8 13.7
Nm/Aeff 0.47 0.78 1.02 0.97 1
Veff/krpm 28.3 47.4 61.3 58.7 61
Page 34
Appendix TPM
General data
+
Unit TPM+
Winding resistance at
Ohm 37.4 40 13.5 4 0.45
20 °C terminal-terminal
Winding inductance
mH 30 30 18.9 11.1 3
terminal-terminal
Electrical time constant
T
e
Max. winding
temperature θ
max
msec 0.8 0.8 1.4 2.8 6.7
°C 155 155 155 155 155
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
You can determine the design for each case with our design software cymex
Tbl-25: Motor data, TPM+ dynamic 560V, i = 61 – 91
9.4.10 Motor data, TPM+ high torque 560V
Unit TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
004
General data
TPM+
010
TPM+
025
TPM+
050
®
.
TPM+
110
Ratio i 22 –
110
154 –
220
22 –5566 –
220
22 –5566 –
220
22 –5566 –88110 –
220
Stator length mm 45 15 60 45 60 60 120 60 60
Pole pair number
p 666666666
p
Maximum torque
T
max
Maximum current
*
I
max
Nm 11.98 4.4 28.9 11.98 56.6 28.9 164.5 88 56.6
Aeff 17 6 40 17 63.5 40 160 100 63.5
Maximum speed rpm 4850 4850 4850 4850 4500 4850 4150 4150 4500
Continuous stall
torque T
0
Continuous stall
current I
*
0
Torque constant
K
t
Voltage constant
K
e
Winding
Nm 3.75 1.44 10.92 4.19 19.28 11.11 63.6 40.35 22.18
Aeff 4.99 1.92 13.08 5.76 17.93 12.6 53.7 40.85 20.5
Nm/
0.83 0.82 0.98 0.83 1.21 1.0 1.17 1.09 1.19
Aeff
Veff/
50.3 49.2 59.2 50.3 73.4 61.0 70.9 66.1 71.9
krpm
Ohm 2.36 15.7 0.47 2.36 0.29 0.47 0.05 0.08 0.29
resistance at 20
°C terminalterminal
en-34 4022-D018396 Revision: 07
Page 35
TPM
+
Appendix
General data
Unit TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
Ratio i 22 –
Winding
110
mH 6 18.9 3 6 2.1 3 0.67 0.9 2.1
154 –
220
inductance
terminal-terminal
Electrical time
constant T
e
Max. winding
temperature θ
max
msec 2.5 1.2 6.4 2.5 7.3 6.4 14 10.8 7.2
°C 155 155 155 155 155 155 155 155 155
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
You can determine the design for each case with our design software cymex
Tbl-26: Motor data, TPM+ high torque 560V
9.4.11 Motor data, TPM+ power 560V, i = 4 – 35
Unit TPM+
22 –5566 –
General data
004
220
TPM+
010
22 –5566 –
220
TPM+
025
22 –5566 –88110 –
220
®
.
TPM+
050
TPM+
110
Stator length mm 30 45 60 60 60
Pole pair number p p 46666
Maximum torque T
Maximum current I
max
* Aeff 5.2 17 40 63.5 100
max
Nm 3.8 12.1 28.9 56.6 88
Maximum speed rpm 6000 6000 6000 5000 4200
Continuous stall torque
T
0
Continuous stall
current I
Torque constant K
Voltage constant K
*
0
t
e
Winding resistance at
Nm 1.25 4.5 11.68 19.3 36.9
Aeff 1.56 5.4 13.7 19 38.6
Nm/Aeff 0.97 0.98 1 1.19 1.09
Veff/krpm 58.5 59.5 61 71.9 66.1
Ohm 21.3 2.2 0.45 0.27 0.08
20 °C terminal-terminal
Winding inductance
mH 22.8 6 3 2.1 0.9
terminal-terminal
Electrical time constant
T
e
Max. winding
temperature θ
max
msec 1.1 2.7 6.7 8 11.2
°C 155 155 155 155 155
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
®
You can determine the design for each case with our design software cymex
.
Tbl-27: Motor data, TPM+ power 560V, i = 4 – 35
Revision: 07 4022-D018396 en-35
Page 36
Appendix TPM
9.4.12 Motor data, TPM+ power 560V, i = 40 – 100
General data
+
Unit TPM+
004
TPM+
010
TPM+
025
TPM+
050
TPM+
110
Stator length mm 15 15 15 15 30
Pole pair number p p 46666
Maximum torque T
Maximum current I
max
* Aeff 3 6 12 33 50
max
Nm 1.9 4.4 7.8 15.6 44.2
Maximum speed rpm 6000 6000 6000 5000 4500
Continuous stall torque
T
0
Continuous stall
current I
Torque constant K
Voltage constant K
*
0
t
e
Winding resistance at
Nm 0.66 1.38 3 5.4 20.74
Aeff 1.0 1.86 4 7.5 21.9
Nm/Aeff 0.78 1.02 0.97 0.91 1.08
Veff/krpm 47.4 61.3 58.7 55.1 65.3
Ohm 40 13.5 4 1.81 0.25
20 °C terminal-terminal
Winding inductance
mH 30 18.9 11.1 5.1 1.9
terminal-terminal
Electrical time constant
T
e
Max. winding
temperature θ
max
msec 0.8 1.4 2.8 2.8 7.6
°C 155 155 155 155 155
* Depending on the static and dynamic loads as well as the lambda factor, the continuous stall
current and the maximum current of the motor needs to be limited if necessary.
You can determine the design for each case with our design software cymex
Tbl-28: Motor data, TPM+ power 560V, i = 40 – 100
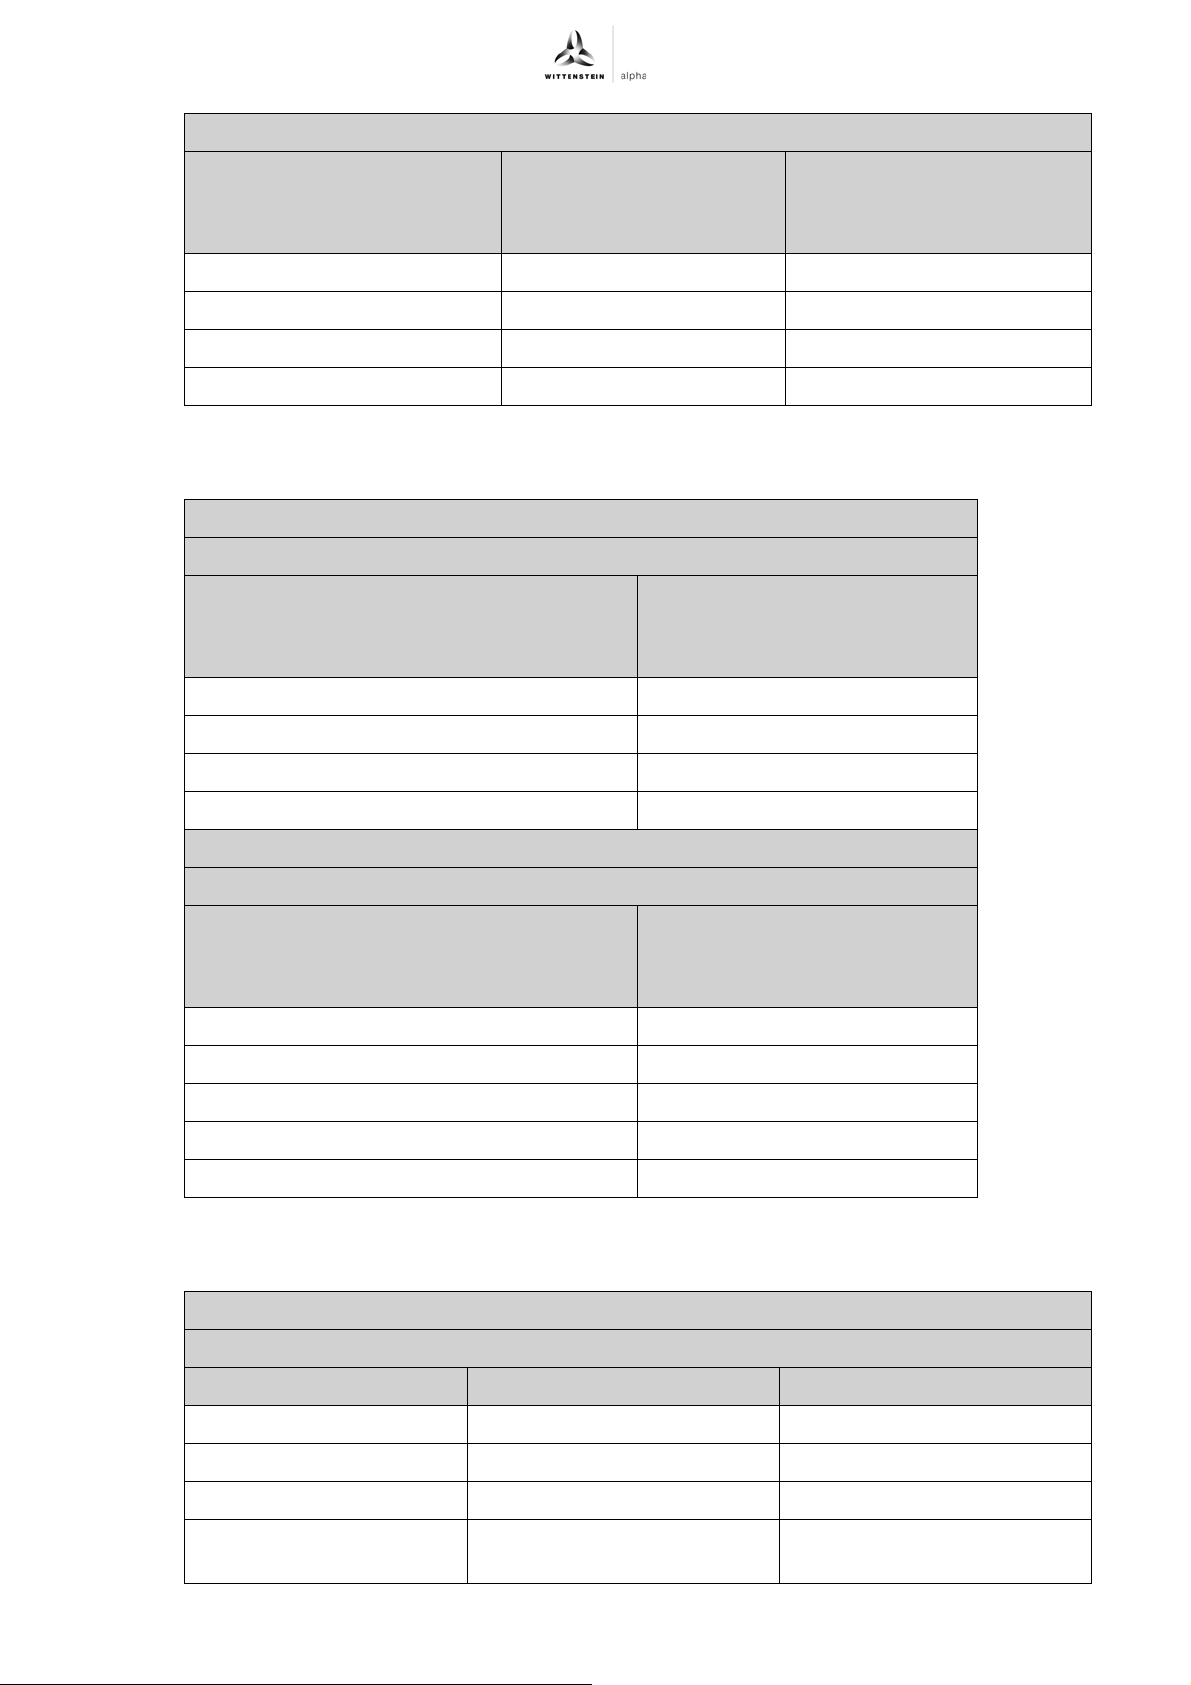
9.4.13 Technical specifications, Resolver
Ordering code: TPMxxxxx-xxxR-xxxx-xxxx-xx-xxx
Size Size 08 Size 15
Type TS2605 N31 E64 TS2620 N21 E11
Pole pair number p 11
Input voltage 7Veff 10kHz 7Veff 10kHz
®
.
TPM+ dynamic 004 TPM+ dynamic 010 – 110
+
high torque 010 – 110
TPM
+
TPM
power 004 – 110
Ratio 0.5+-5% 0.5+ -5%
Fault +- 10'max +- 10'max
Zero voltage 20mVeff max 20mVeff max
Phase shift +10° nominal 0° nominal
en-36 4022-D018396 Revision: 07
Page 37
+
TPM
Ordering code: TPMxxxxx-xxxR-xxxx-xxxx-xx-xxx
TPM+ dynamic 004 TPM+ dynamic 010 – 110
TPM
TPM
Impedance ZR0 140 ohm 70 + j 100 ohm
Impedance ZS0 – 180 + j 300 ohm
Impedance ZSS 120 ohm 175 + j 257 ohm
Max. operating temperature 155 °C 155 °C
Tbl-29: Technical specifications, Resolver
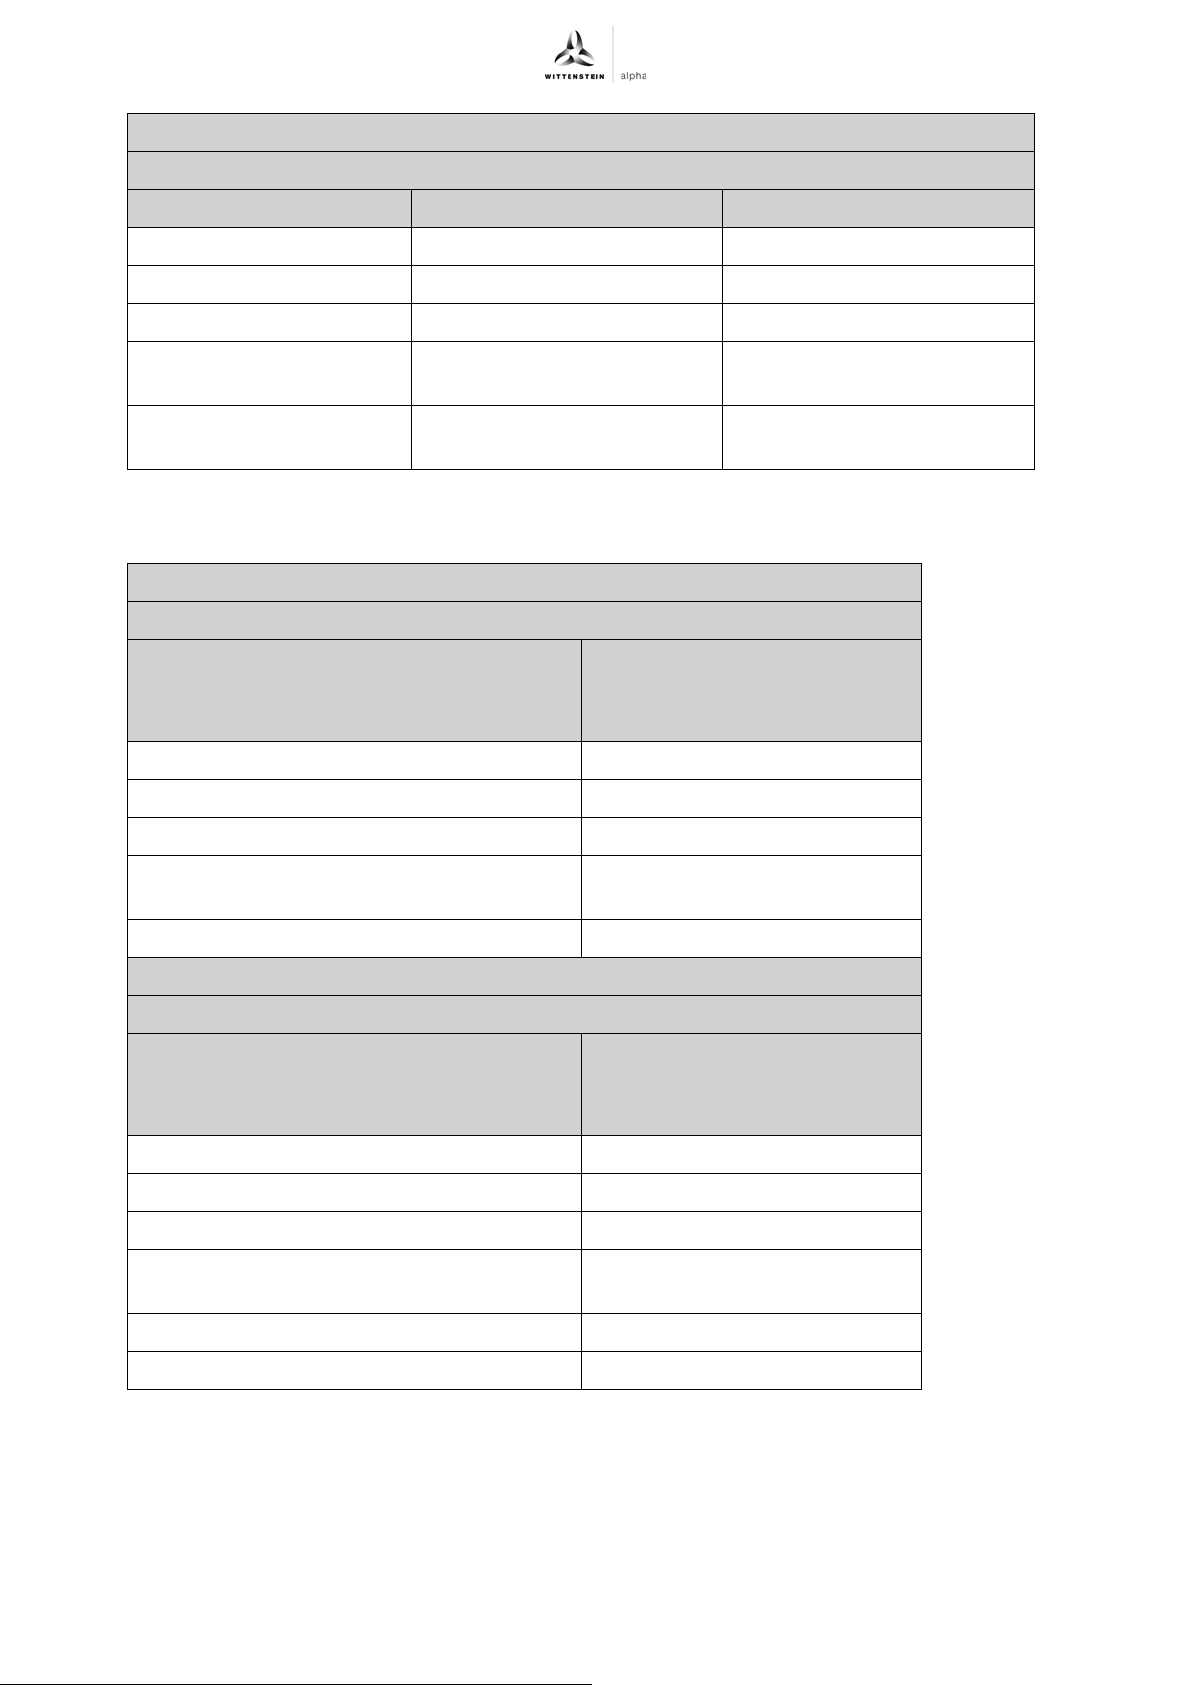
9.4.14 Technical specifications Stegmann Hiperface absolute encoder
Singleturn
Ordering code: TPMxxxxx-xxxN-xxxx-xxxx-xx-xxx
TPM+ dynamic 004 –110
+
TPM
high torque 010 –110
+
TPM
power 004 –110
Appendix
+
high torque 010 – 110
+
power 004 – 110
Type SKS36
Operating voltage 7-12 V
Protocol Hiperface
Number of SinCos periods per revolution 128
Multiturn
Ordering code: TPMxxxxx-xxxK-xxxx-xxxx-xx-xxx
TPM+ dynamic 004 –110
+
high torque 010 –110
TPM
+
TPM
power 004 –110
Type SKM36
Operating voltage 7-12 V
Protocol Hiperface
Number of SinCos periods per revolution 128
Number of Multiturn revolutions 4096
Tbl-30: Technical specifications Stegmann Hiperface
9.4.15 Technical specifications Stegmann Hiperface absolute encoder, Rockwell option
Singleturn
Ordering code: TPM xxxx-xxxE-xxxx-xxxx-x5-xxx
TPM+ dynamic 560V U
TPM+ dynamic 320V U
DCBus
DCBus
Type SKS36 SKS36
Operating voltage 7-12 V 5 V
Protocol Hiperface Hiperface
Number of SinCos
128 128
periods per revolution
Revision: 07 4022-D018396 en-37
Page 38
Appendix TPM
Multiturn
Ordering code: TPM xxxx-xxxV-xxxx-xxxx-x5-xxx
+
TPM+ dynamic 560V U
DCBus
TPM+ dynamic 320V U
Type SKM36 SKM36
Operating voltage 7-12 V 5 V
Protocol Hiperface Hiperface
Number of SinCos
128 128
periods per revolution
Number of Multiturn
4096 4096
revolutions
Tbl-31: Technical specifications Stegmann Hiperface
9.4.16 Technical specifications Heidenhain EnDat absolute encoder
Singleturn EnDat
Ordering code: TPMxxxxx-xxxS-xxxx-xxxx-xx-xxx
TPM+ dynamic 004 –110
+
high torque 010 –110
TPM
+
TPM
power 004 –110
Type ECN 1113
DCBus
Operating voltage 5 V
Protocol EnDat 2.1
Distinguishable positions via EnDat
8192
protocol/revolutions
Number of SinCos periods per revolution 512
Multiturn EnDat
Ordering code: TPMxxxxx-xxxM-xxxx-xxxx-xx-xxx
TPM+ dynamic 004 –110
+
TPM
high torque 010 –110
+
TPM
power 004 –110
Type EQN 1125
Operating voltage 5 V
Protocol EnDat 2.1
Distinguishable positions via EnDat
8192
protocol/revolutions
Number of SinCos periods per revolution 512
Number of Multiturn revolutions 4096
Tbl-32: Technical specifications Heidenhain EnDat
en-38 4022-D018396 Revision: 07
Page 39
+
TPM
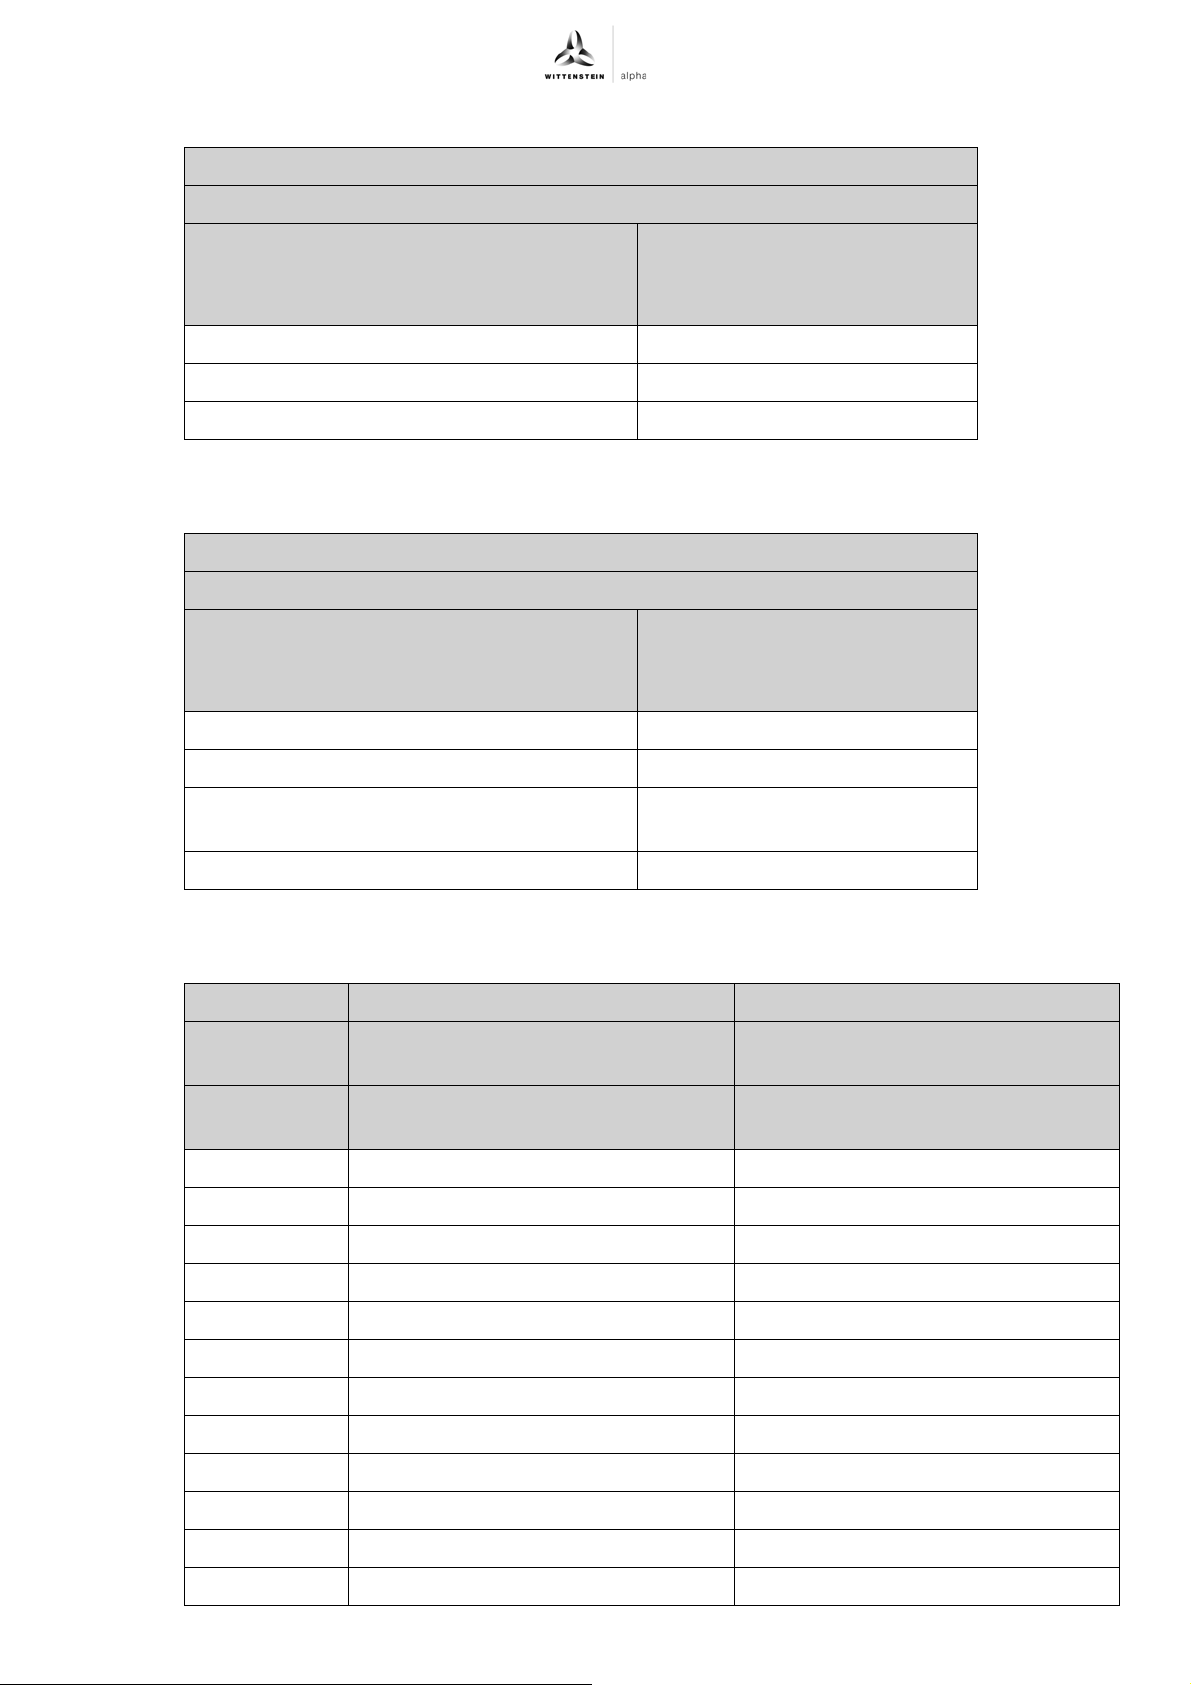
9.4.17 Technical specifications Heidenhain Incremental
Incremental
Ordering code: TPMxxxxx-xxxI-xxxx-xxxx-xx-xxx
TPM+ dynamic 004 –110
TPM
Type ERN 1185
Operating voltage 5 V
Number of SinCos periods per revolution 2048
Tbl-33: Technical specifications Heidenhain Incremental
9.4.18 Technical specifications TTL Encoder incremental
TTL Encoder incremental
Ordering code: TPMxxxxx-xxxT-xxxx-xxxx-xx-xxx
TPM+ dynamic 004 –110
TPM
+
high torque 010 –110
+
TPM
power 004 –110
+
high torque 010 –110
+
TPM
power 004 –110
Appendix
Type Sick-Stegmann CKS36
Operating voltage 5 V
Commutation signals The motor polar pair number
appropriately programmed.
Increments per revolution 2048
Tbl-34: Technical specifications TTL Encoder incremental
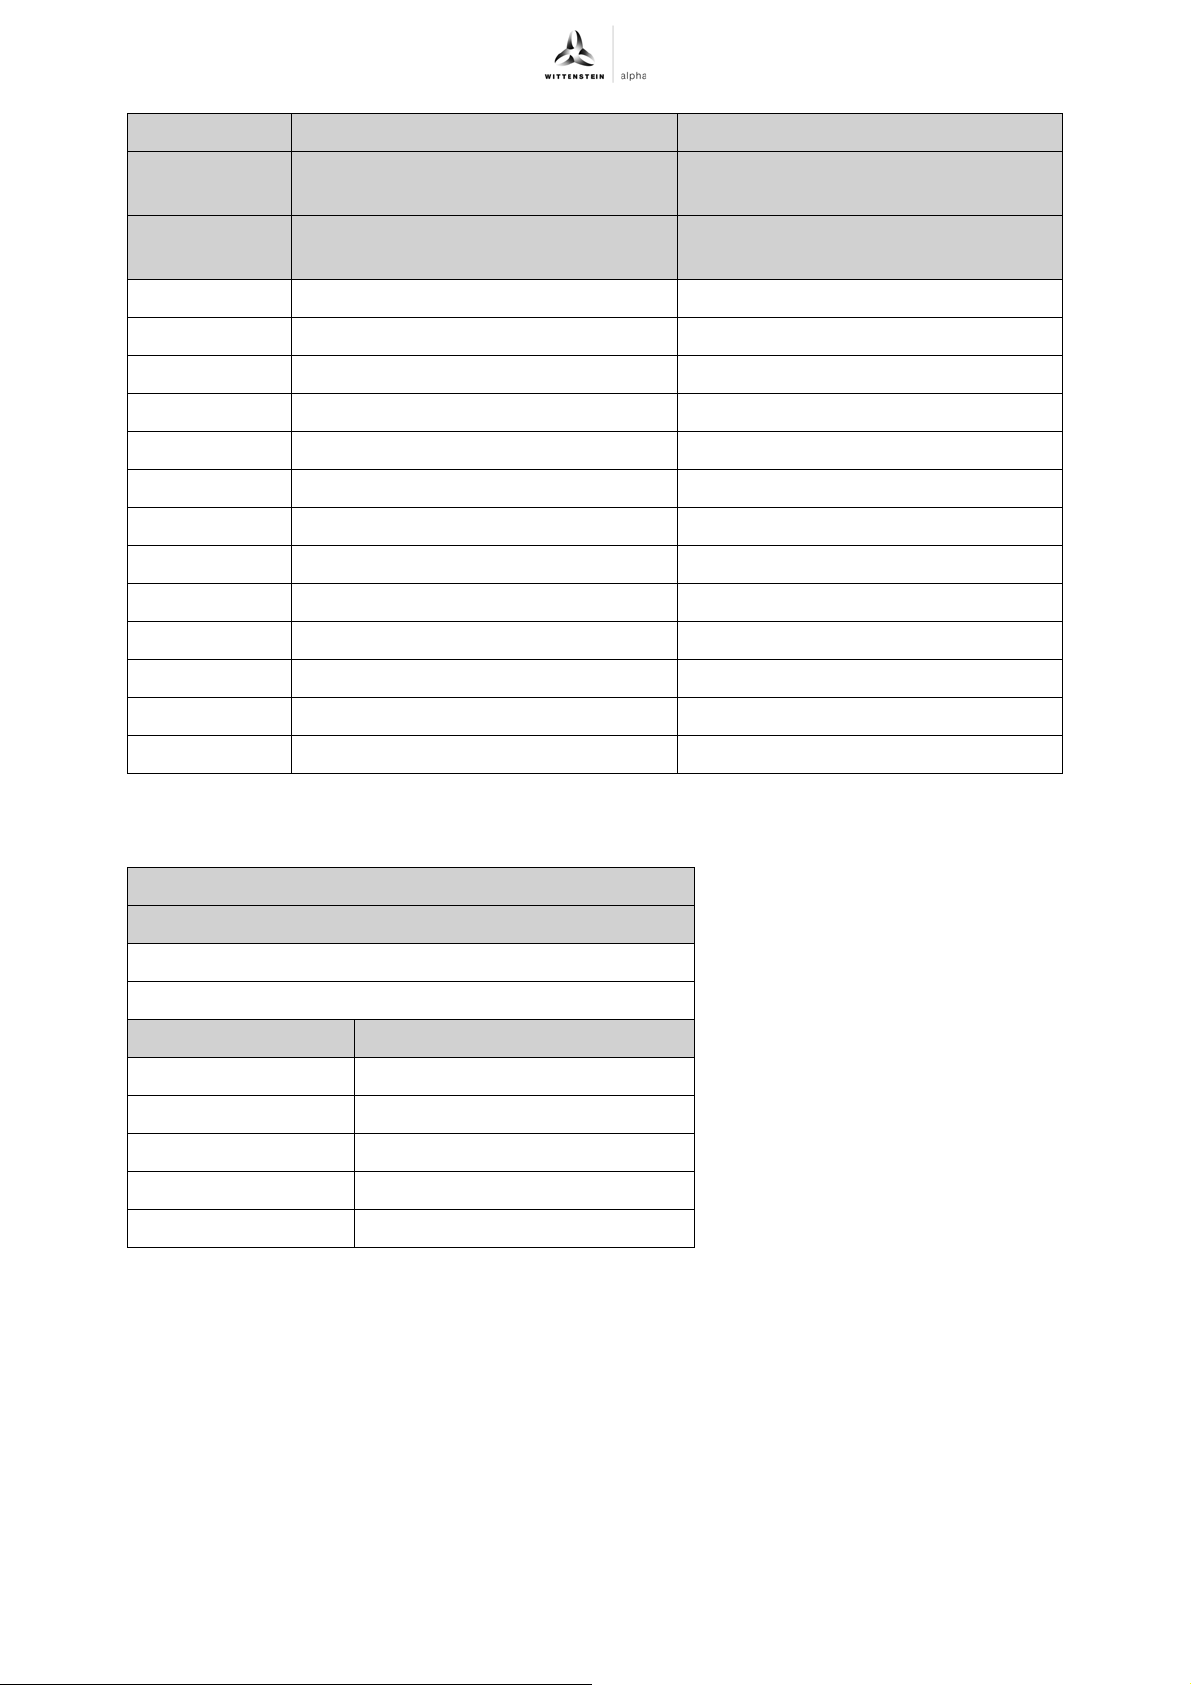
9.4.19 Technical specifications temperature sensors KTY and NTC
Type KTY 84-130 NTC P1H104
Ordering
TPMxxxxx-xxxx-xKxx-xxxx-xx-xxx TPMxxxxx-xxxx-xNxx-xxxx-xx-xxx
code:
Temperature
Resistance, type [kohm] Resistance, type [kohm]
[C]
-30 0.391 1770
-20 0.424 971
-10 0.460 553
0 0.498 327
10 0.538 199
20 0.581 125
25 0.603 100
30 0.626 81
40 0.672 53
50 0.722 36
60 0.773 25
70 0.826 18
Revision: 07 4022-D018396 en-39
Page 40
Appendix TPM
Type KTY 84-130 NTC P1H104
+
Ordering
TPMxxxxx-xxxx-xKxx-xxxx-xx-xxx TPMxxxxx-xxxx-xNxx-xxxx-xx-xxx
code:
Temperature
Resistance, type [kohm] Resistance, type [kohm]
[C]
80 0.882 13
90 0.940 9.2
100 1.000 6.8
110 1.062 5.2
120 1.127 3.9
130 1.194 3
140 1.262 2.4
150 1.334 1.9
160 1.407 1.5
170 1.482 1.2
180 1.560 1
190 1.640 0.8
200 1.722 0.7
Tbl-35: Technical specifications temperature sensors KTY and NTC
9.4.20 Technical specifications temperature sensor PTC
PTC STM 160
Ordering code: TPMxxxxx-xxxx-xPxx-xxxx-xx-xxx
Deactivation in case of fault
Characteristic line in accordance with DIN 44081/44082
Temperature [C] Resistance [ohm]
< 140 20 - 250
140 - 155 250 - 550
155 - 165 550 - 1330
165 - 175 1330 - 4000
> 175 > 4000
Tbl-36: Technical specifications temperature sensor PTC
en-40 4022-D018396 Revision: 07
Page 41
+
TPM
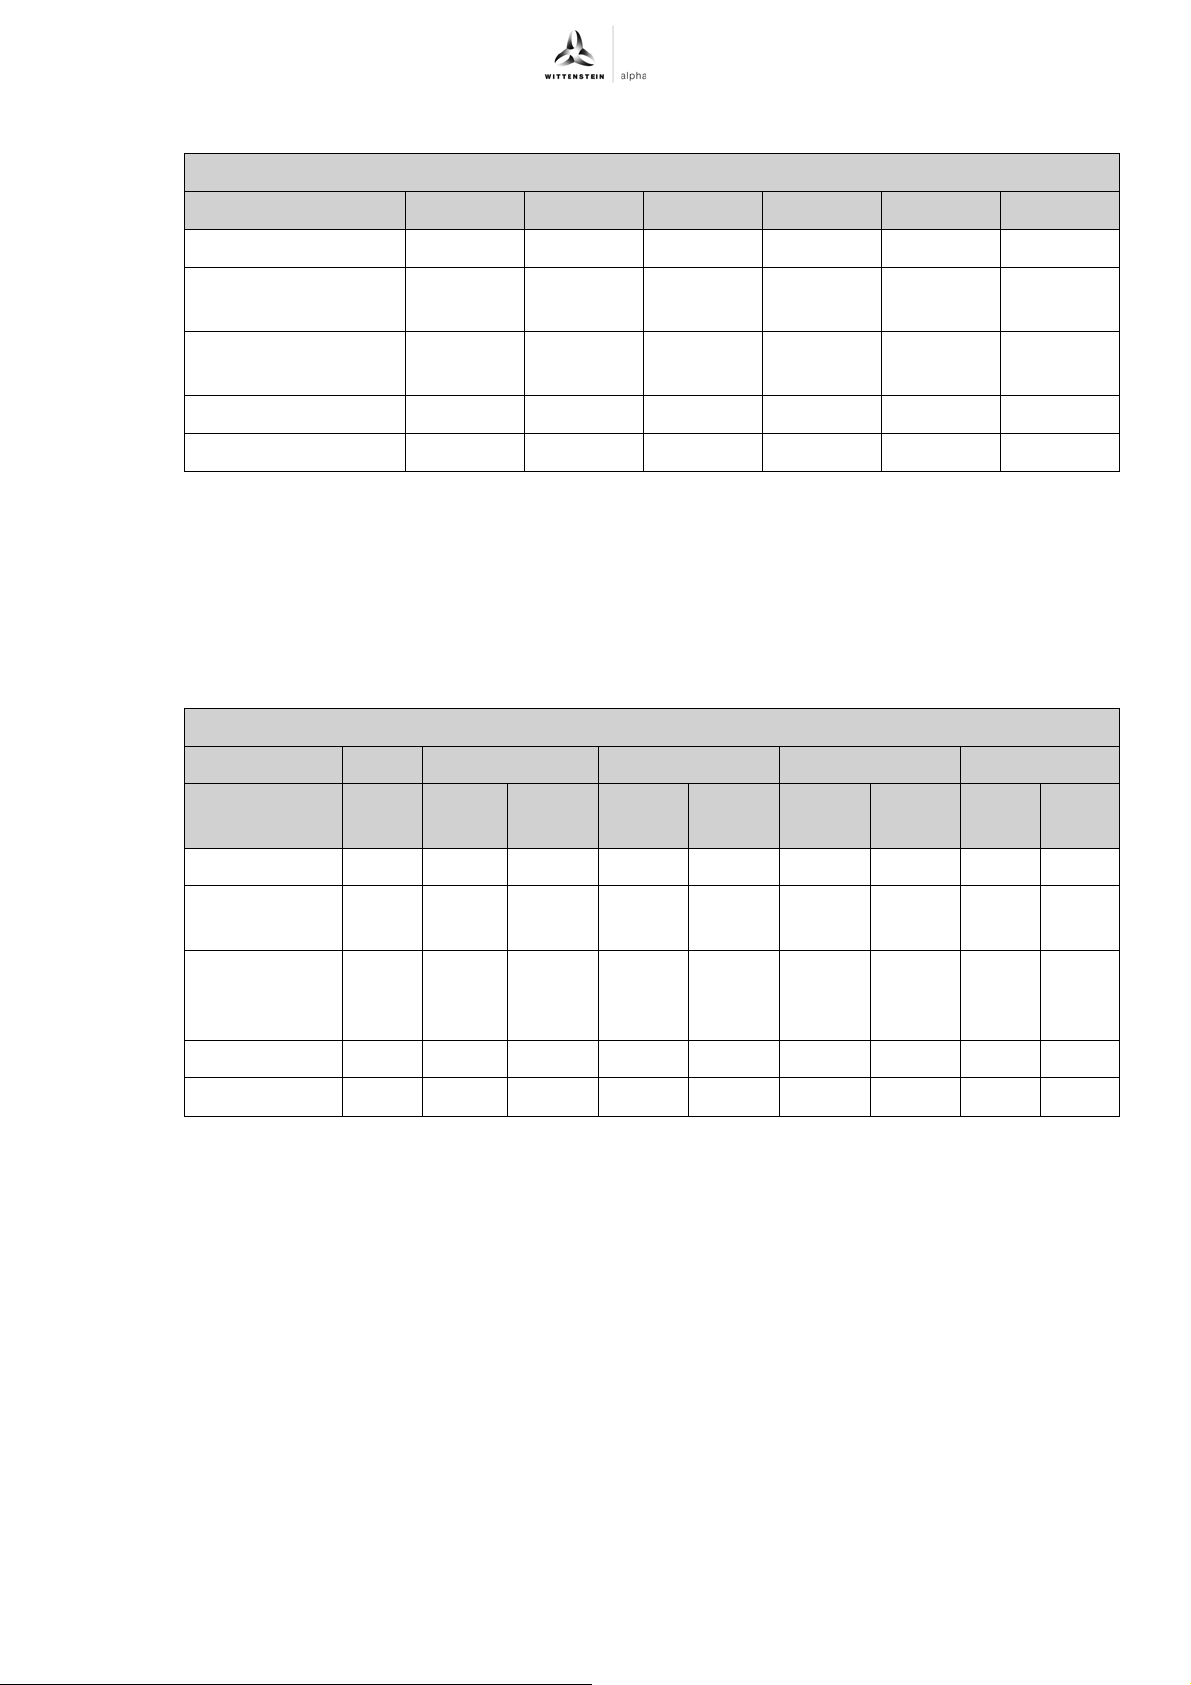
9.4.21 Technical specifications brake TPM+ dynamic
Ordering code: TPM xxxx-xxxx-xxBx-xxxx-xx-xxx
Unit TPM+ 004 TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
Voltage V DC 24 24 24 24 24
Appendix
Power
A DC 0.42 0.42 0.58 0.71 0.71
consumption
Holding torque at
Nm 1.1 1.1 4.5 13 13
120 C
Opening time msec 11 11 30 42 42
Closing time msec 10 10 20 20 20
Tbl-37: Technical specifications brake TPM+ dynamic
The listed opening and closing times are noted without the use of an additional wiring of the brake.
To avoid interfering signals from the switching of the brake, in general an additional wiring, e.g.
in form of a varistor, should be added. Observe the requirements for this of the applied servo
controller manufacturer.
9.4.22 Technical specifications brake TPM
Ordering code: TPMAxxxx-xxxx-xxBx-xxxx-xx-xxx
Unit TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
Ratio i 22 –
110
154 –
220
+
high torque
22 –55 66 –
220
22 –55 66 –
220
22 –88110 –
220
Voltage V DC 24 24 24 24 24 24 24 24
Power
A DC 0.58 0.46 0.71 0.58 1.0 0.71 1.67 1.0
consumption
Holding
Nm 4.5 1.8 13 4.5 23 13 72 23
torque at 120
C
Opening time msec 30 30 42 30 50 42 200 50
Closing time msec 20 25 20 20 40 20 50 40
Tbl-38: Technical specifications brake TPM+ high torque
The listed opening and closing times are noted without the use of an additional wiring of the brake.
To avoid interfering signals from the switching of the brake, in general an additional wiring, e.g.
in form of a varistor, should be added. Observe the requirements for this of the applied servo
controller manufacturer.
Revision: 07 4022-D018396 en-41
Page 42
Appendix TPM
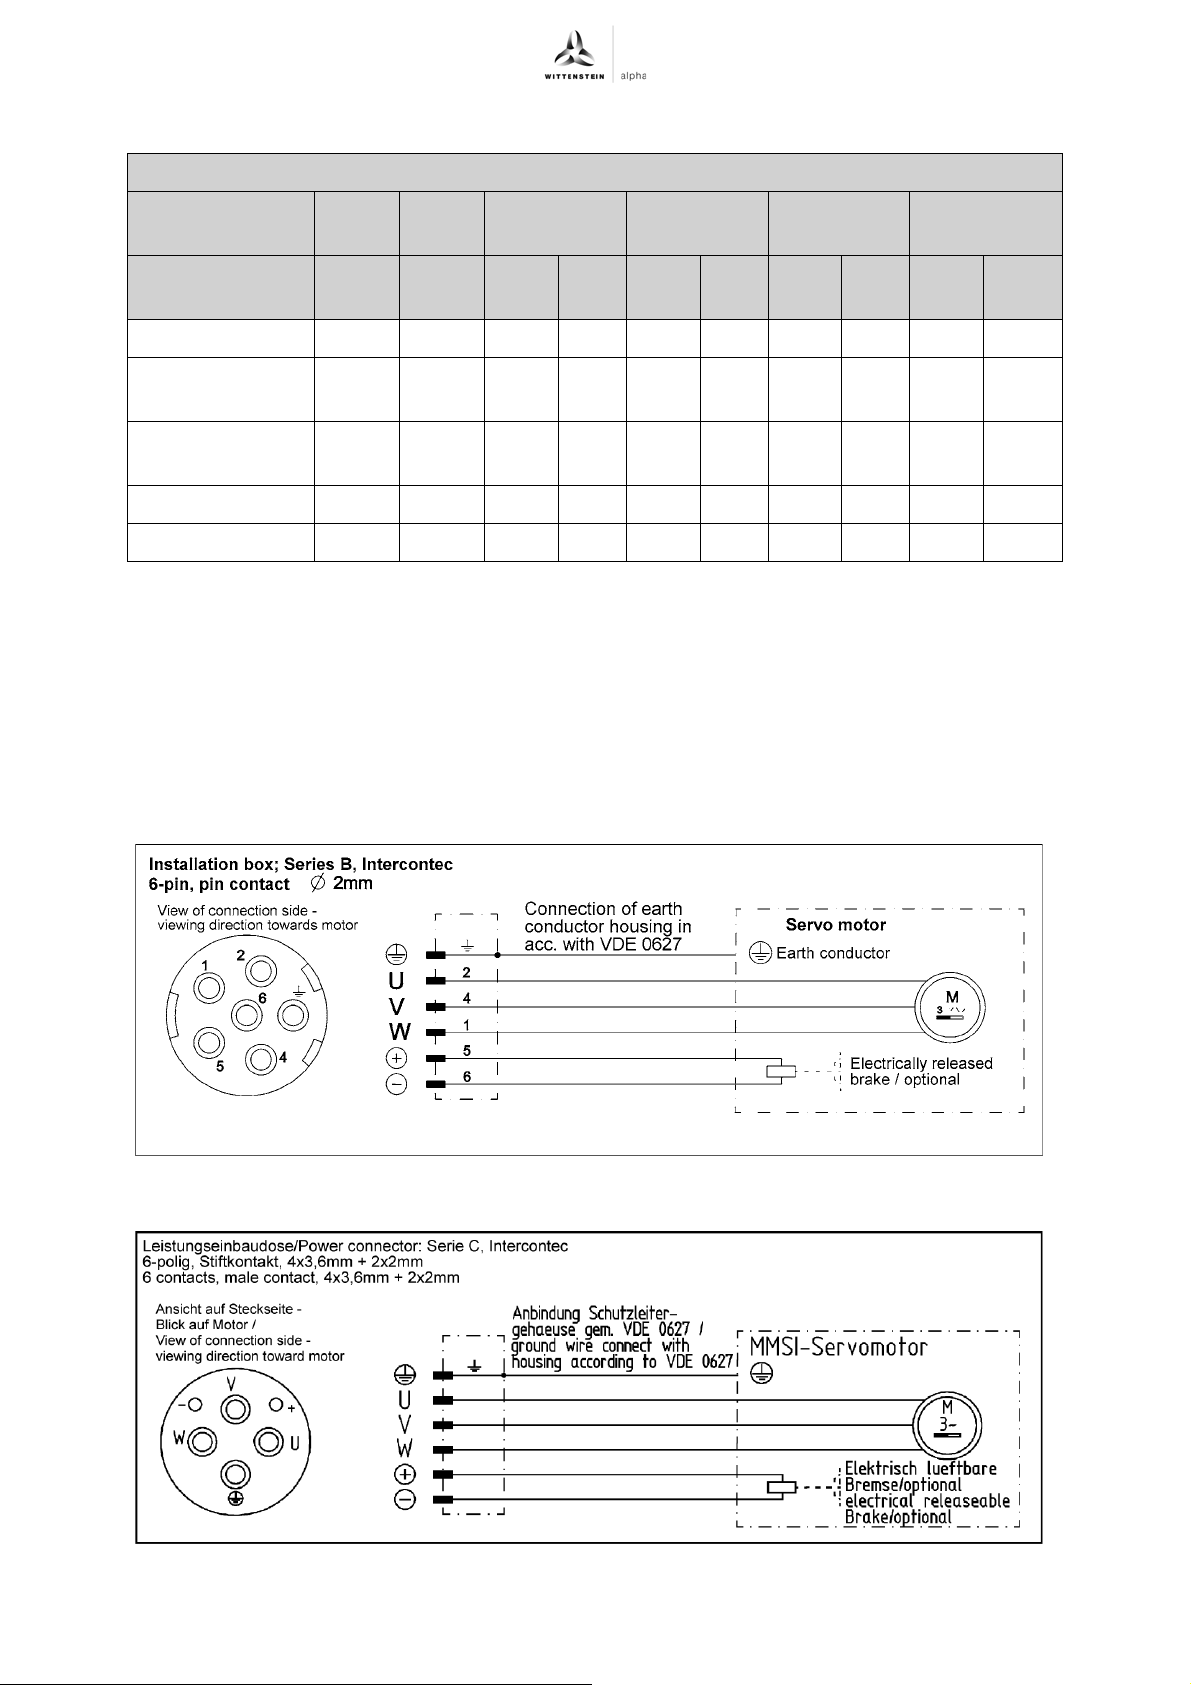
9.4.23 Technical specifications brake TPM+ power
Ordering code: TPMPxxxx-xxxx-xxBx-xxxx-xx-xxx
+
Ratio i 4 –70 100 4 –70 100 4 –70 100 4 –50 70 –
Voltage V DC 24 24 24 24 24 24 24 24 24
Power
consumption
Holding torque
at 120 C
Opening time msec 11 30 30 42 42 50 50 200 140
Closing time msec 10 20 25 20 20 40 50 50 90
The listed opening and closing times are noted without the use of an additional wiring of the brake.
To avoid interfering signals from the switching of the brake, in general an additional wiring, e.g.
in form of a varistor, should be added. Observe the requirements for this of the applied servo
controller manufacturer.
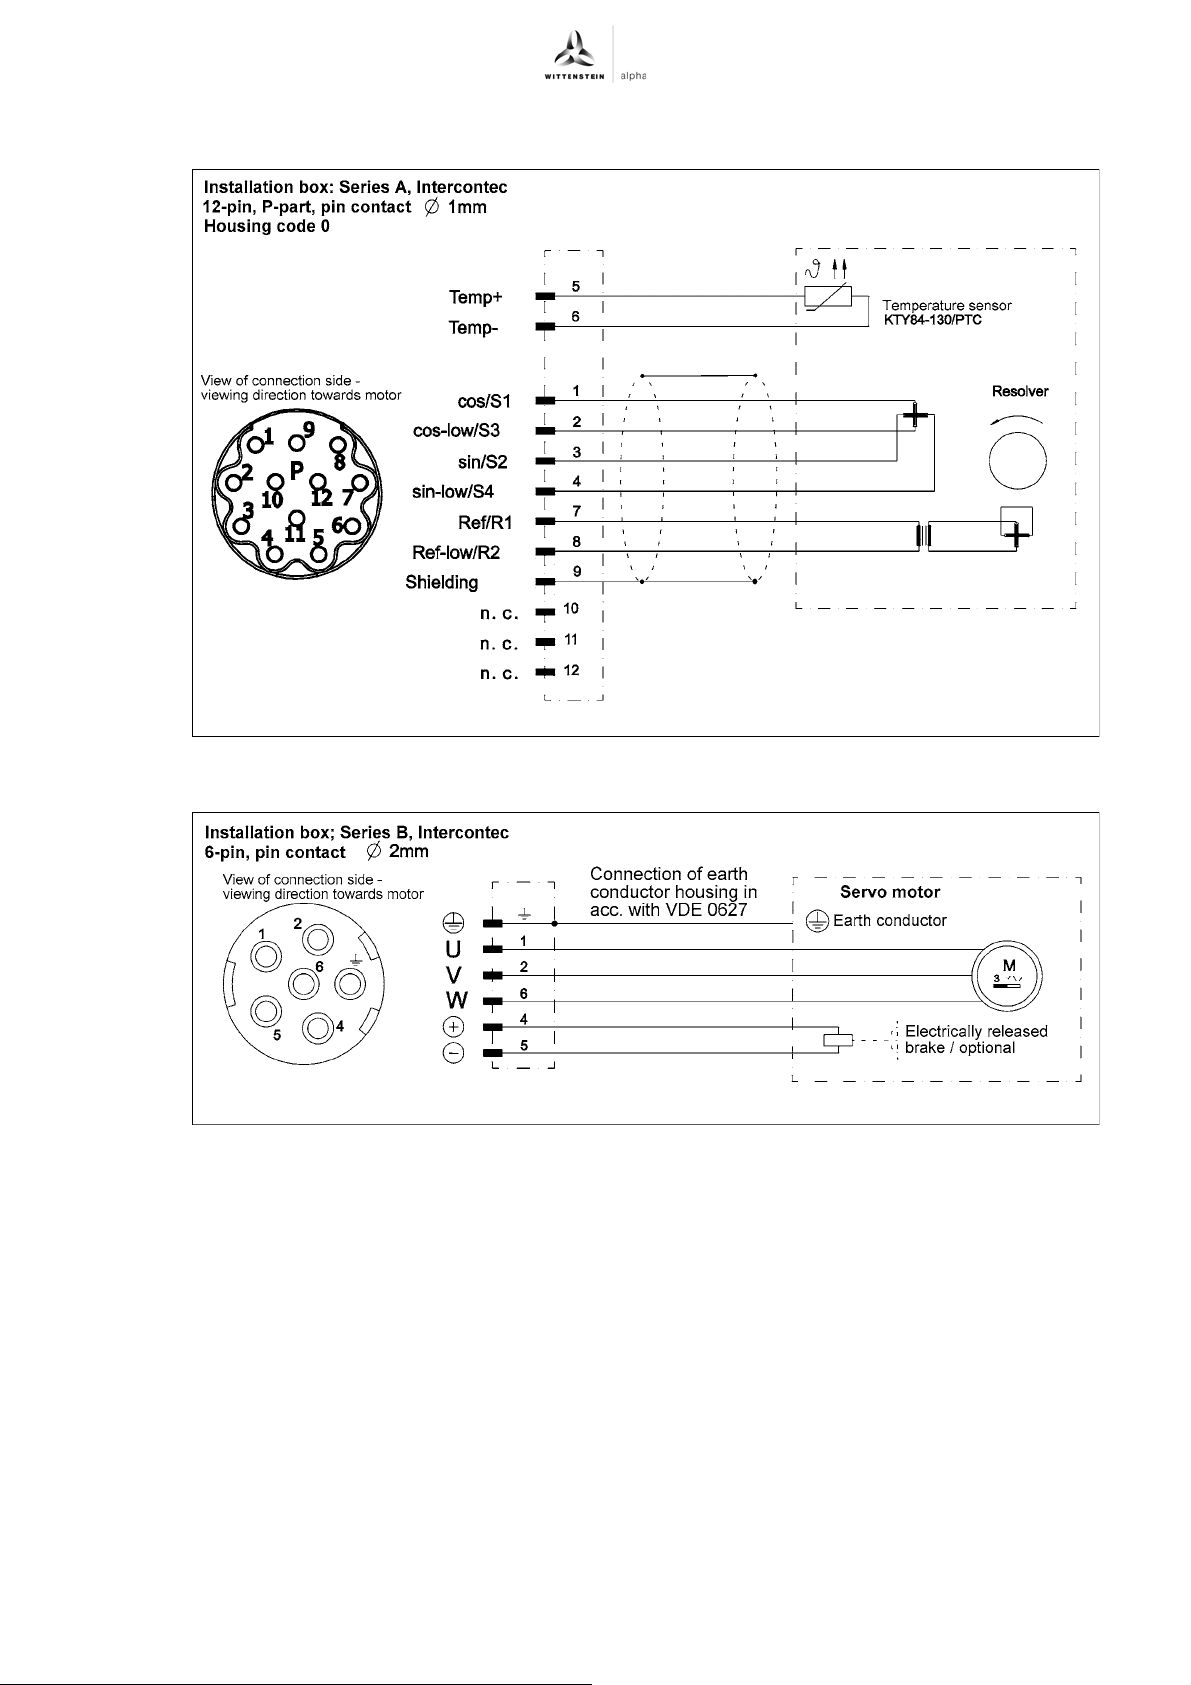
9.4.24 Pin assignment 1 Design with resolver —output size 1 (pin assignment 1)
Unit TPM+
004
A DC 0.42 0.58 0.46 0.71 0.71 1 1 1.67 1.67
Nm 1.1 4.5 1.8 13 6 23 11 72 25
Tbl-39: Technical specifications brake TPM+ power
TPM+ 010 TPM+ 025 TPM+ 050 TPM+ 110
100
Design with resolver and optical encoder —output size 1.5 (pin assignment 1)
en-42 4022-D018396 Revision: 07
Page 43
TPM
+
Option “R” —signal (pin assignment 1)
Appendix
Design with optical encoder —output (pin assignment 1)
Revision: 07 4022-D018396 en-43
Page 44
Appendix TPM
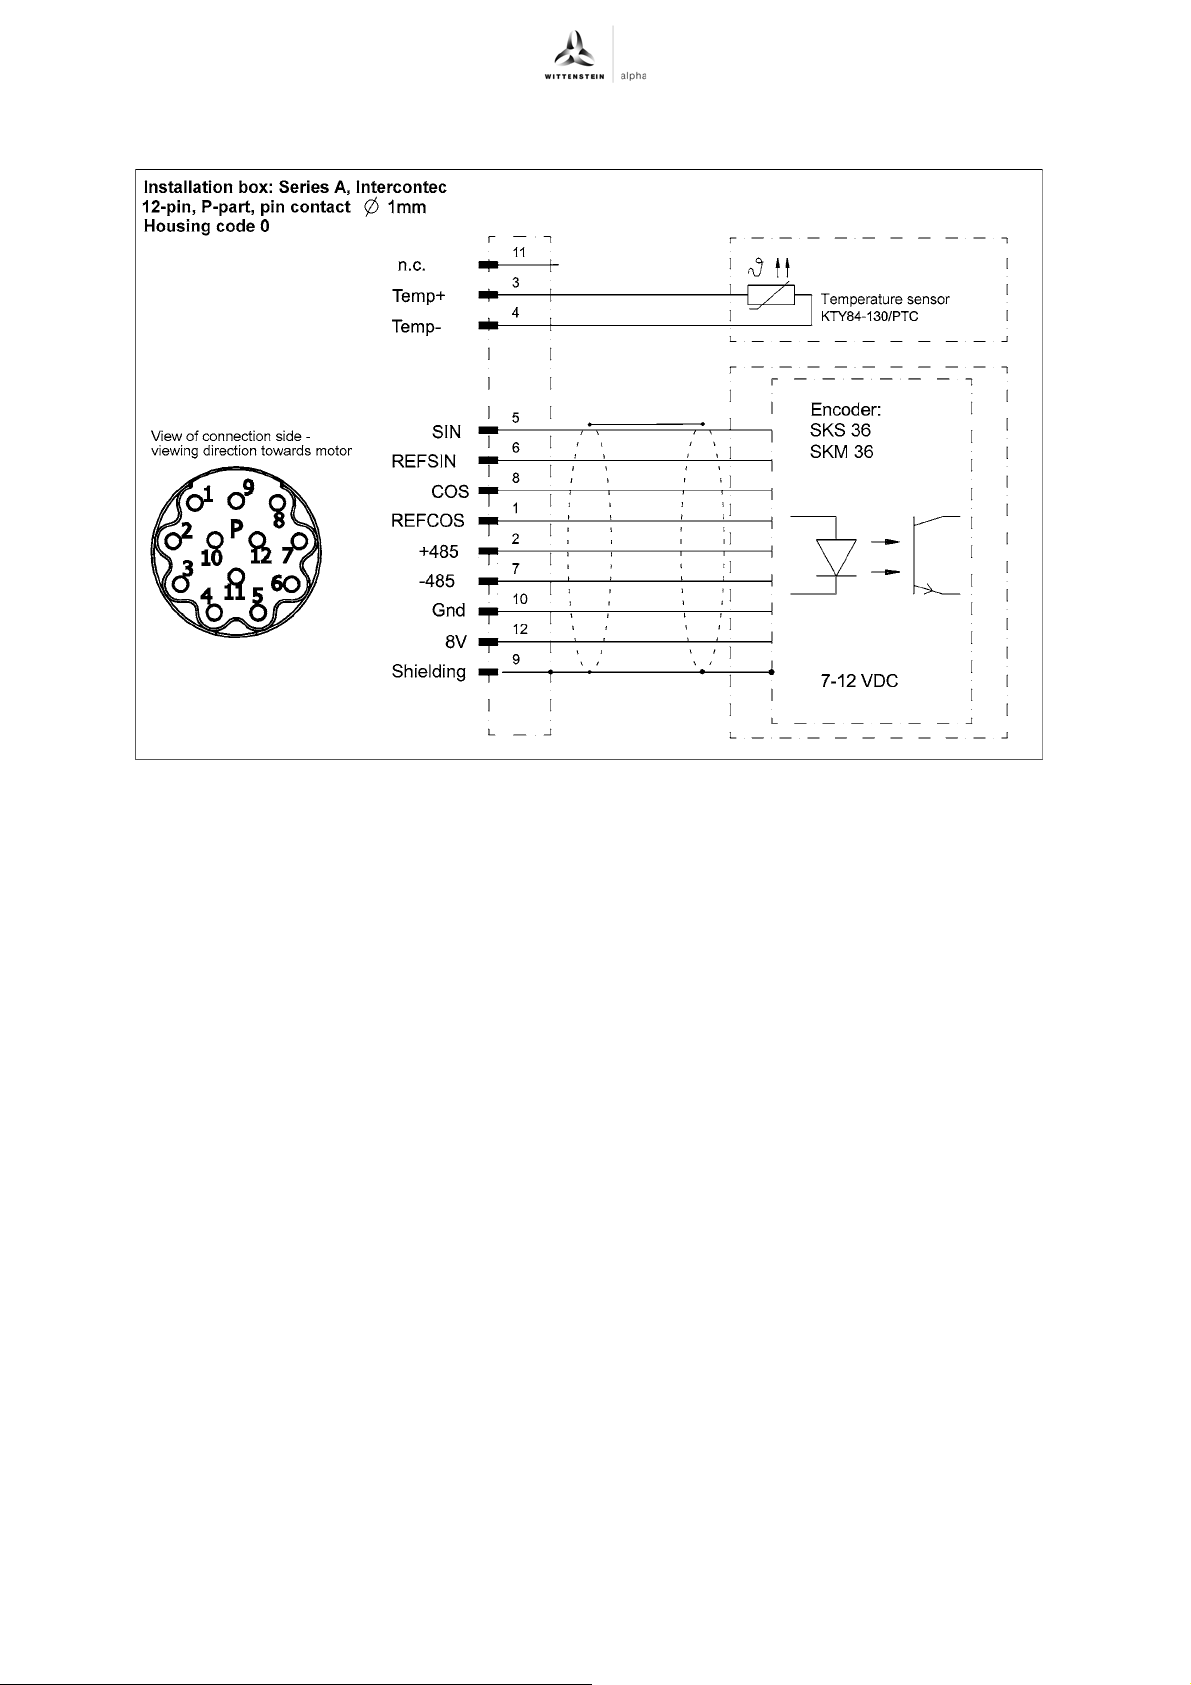
Option “N” and “K” —signal (pin assignment 1)
+
en-44 4022-D018396 Revision: 07
Page 45
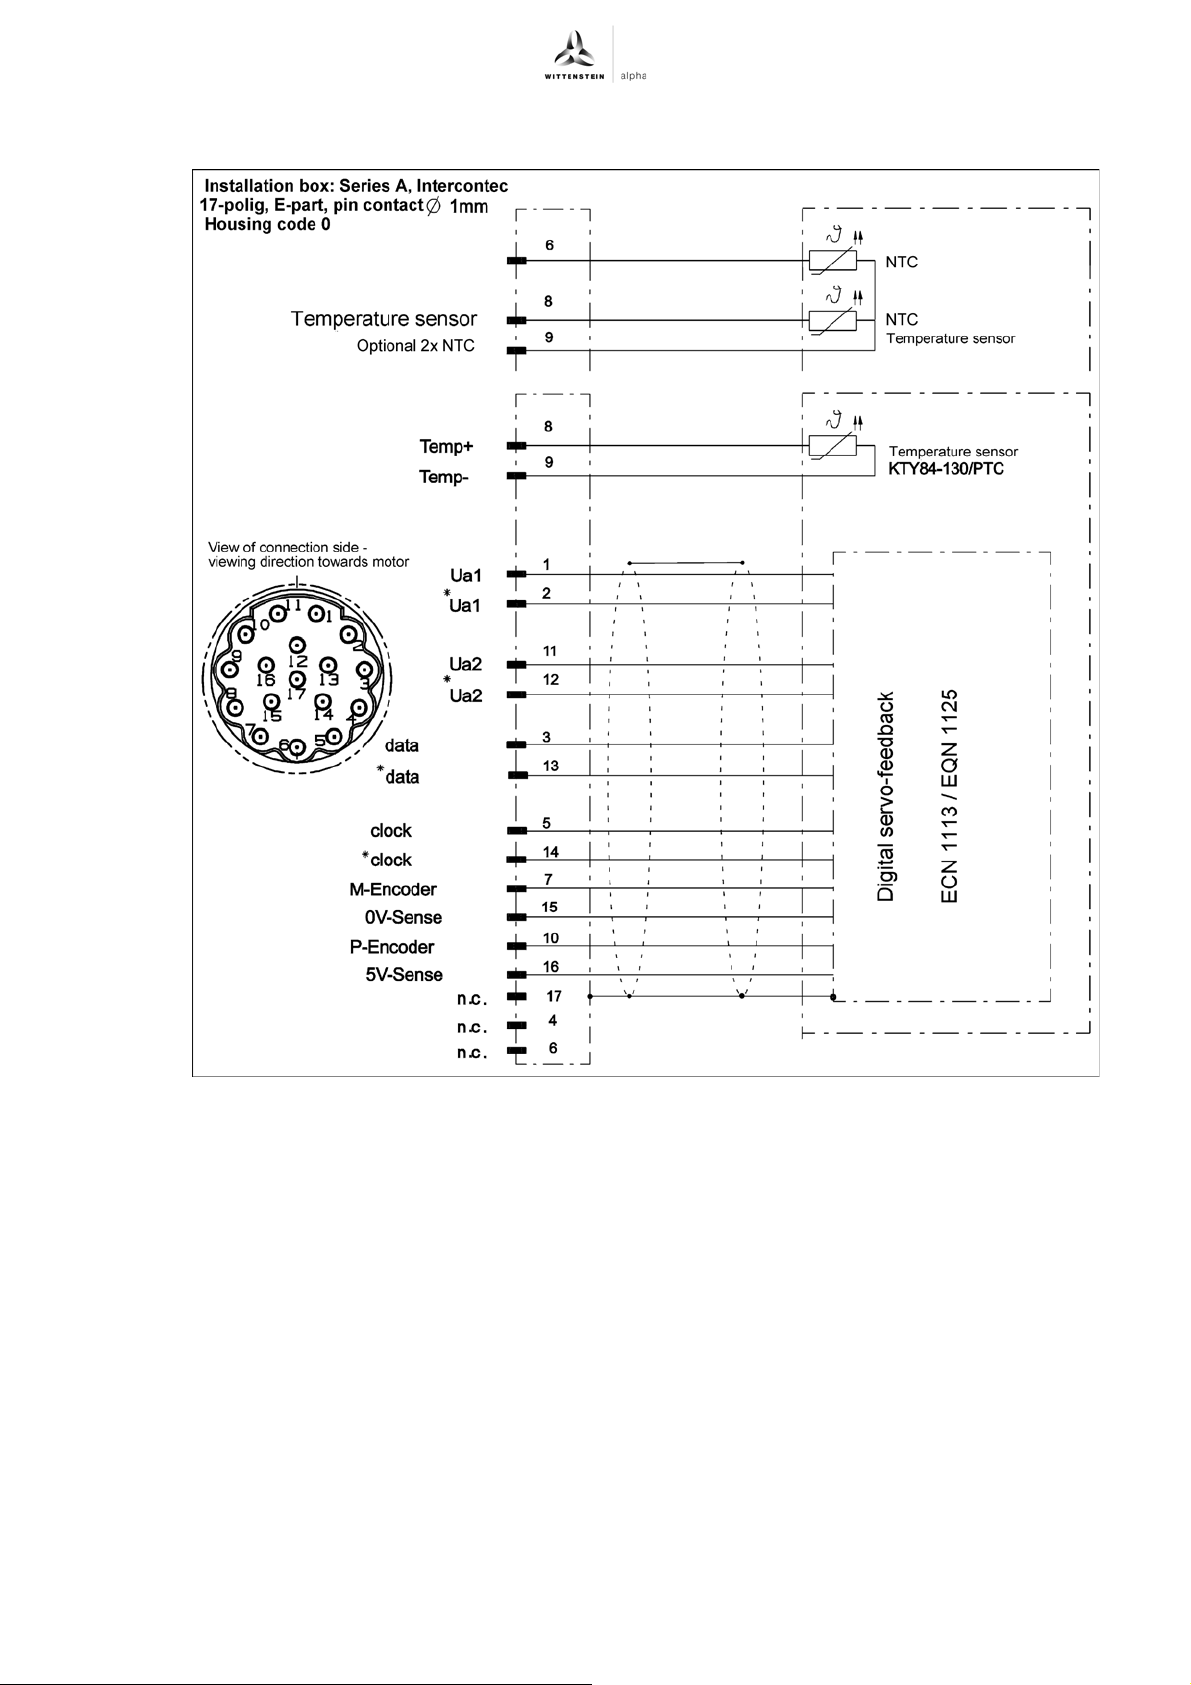
TPM
+
Option “S” and “M” —signal (pin assignment 1)
Appendix
Revision: 07 4022-D018396 en-45
Page 46
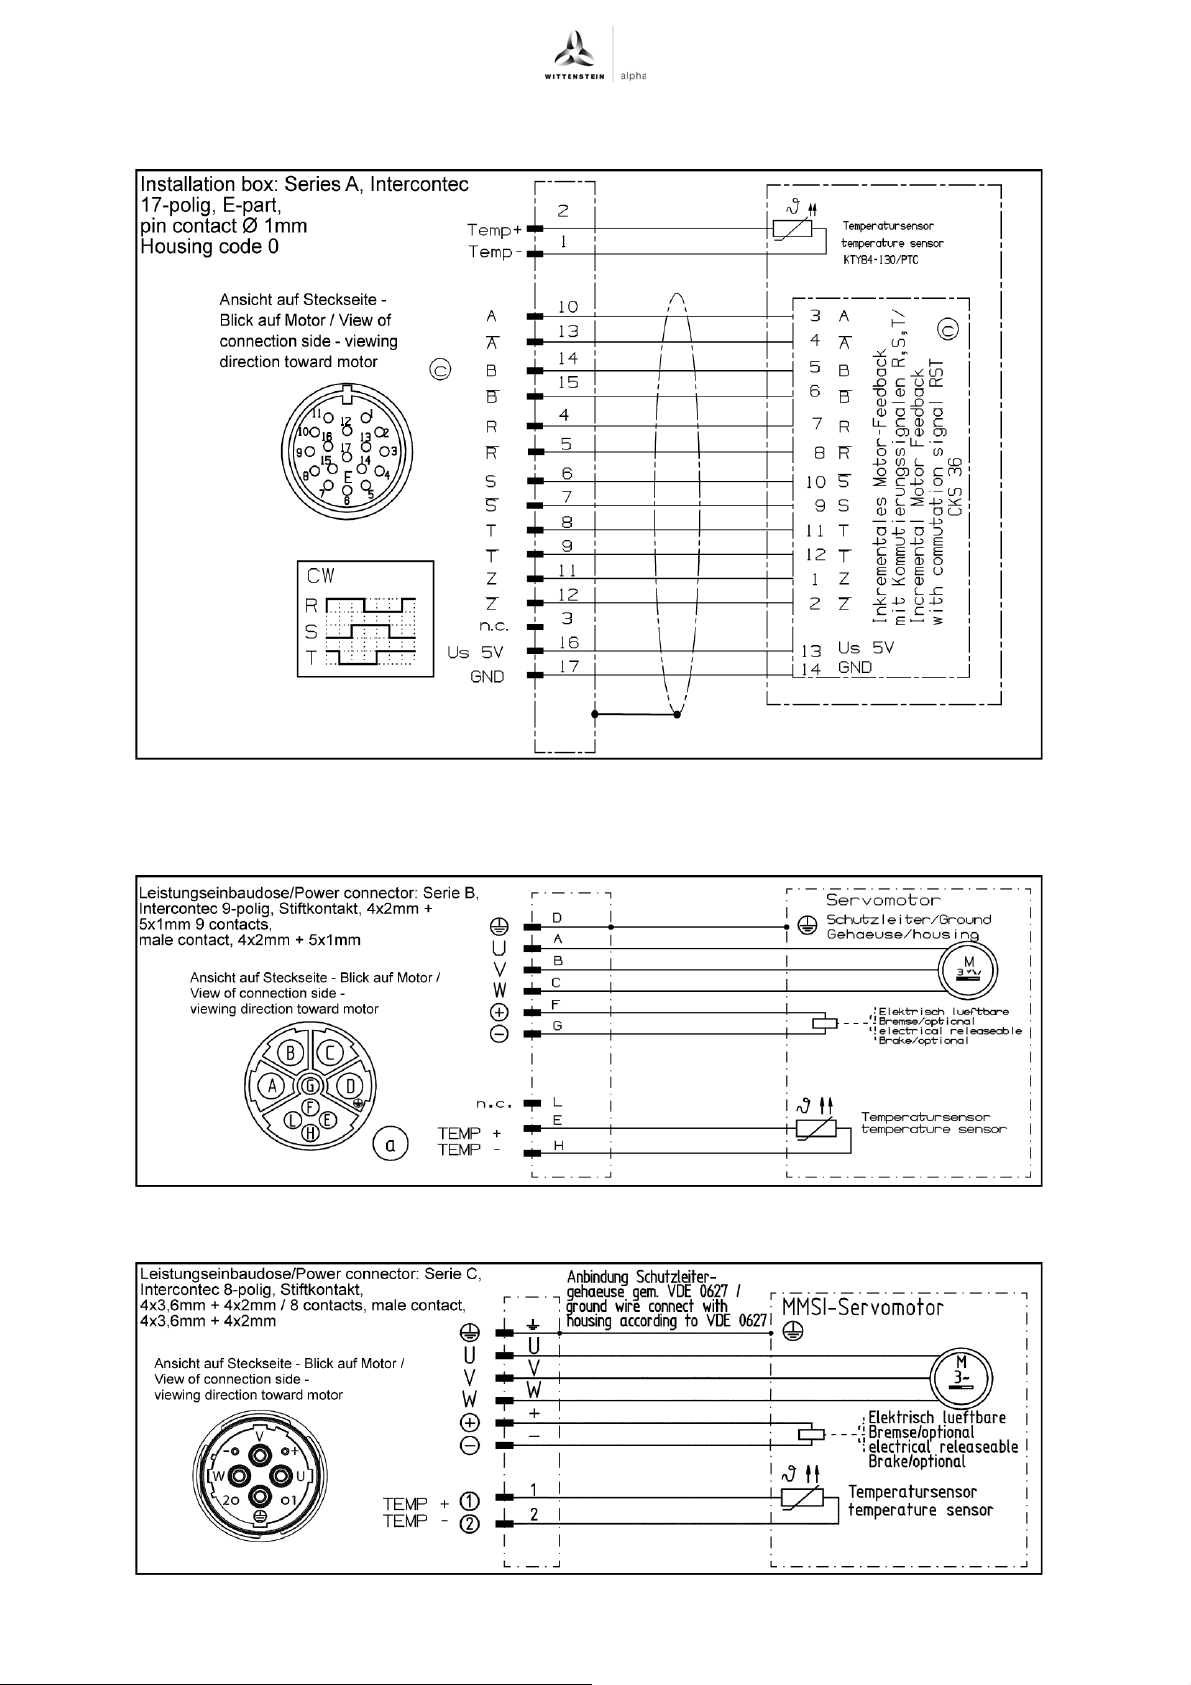
Appendix TPM
Option “T” —signal (pin assignment 1)
+
9.4.25 Pin assignment 4 Design with resolver, EnDat- and Hiperface encoder —output size 1 (pin assignment 4)
Design with resolver, EnDat- and Hiperface encoder —output size 1.5 (pin assignment 4)
en-46 4022-D018396 Revision: 07
Page 47
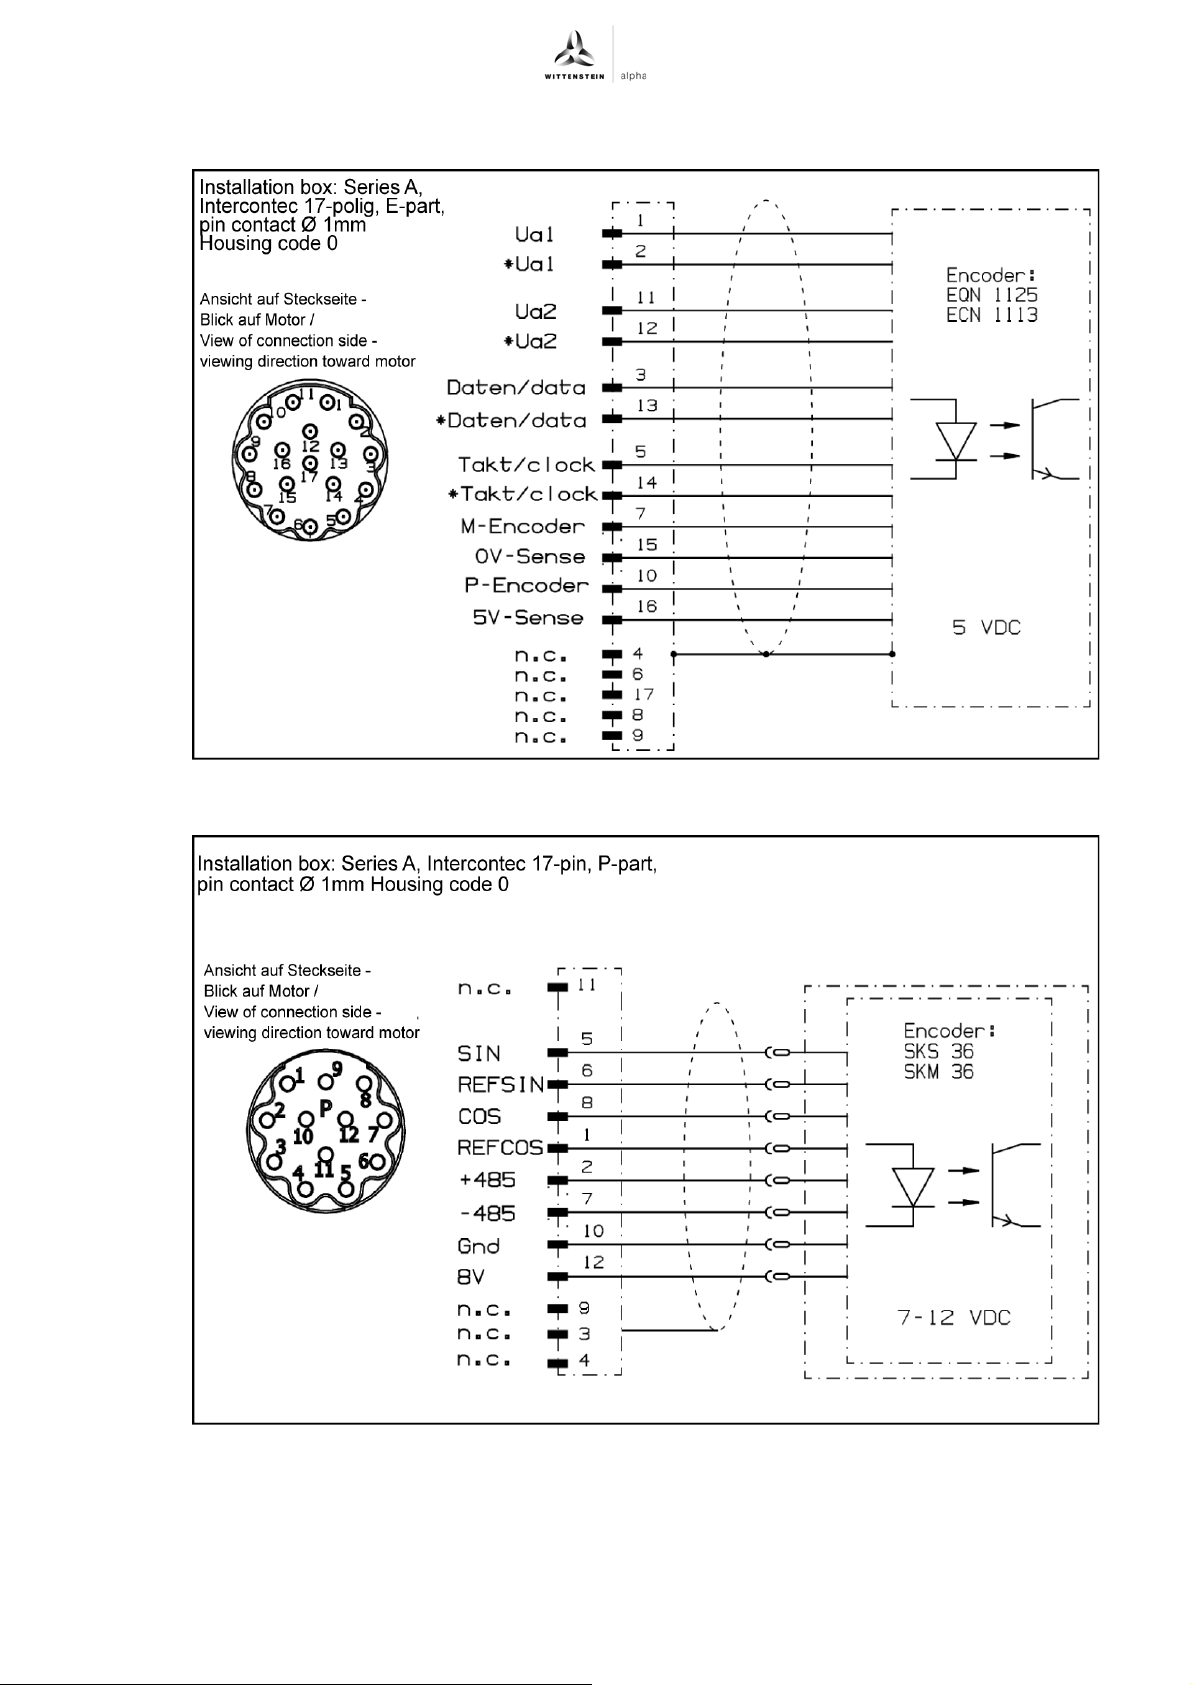
TPM
+
Option “S” and “M” —signal (pin assignment 4)
Appendix
Option “N” and “K” —signal (pin assignment 4)
Revision: 07 4022-D018396 en-47
Page 48
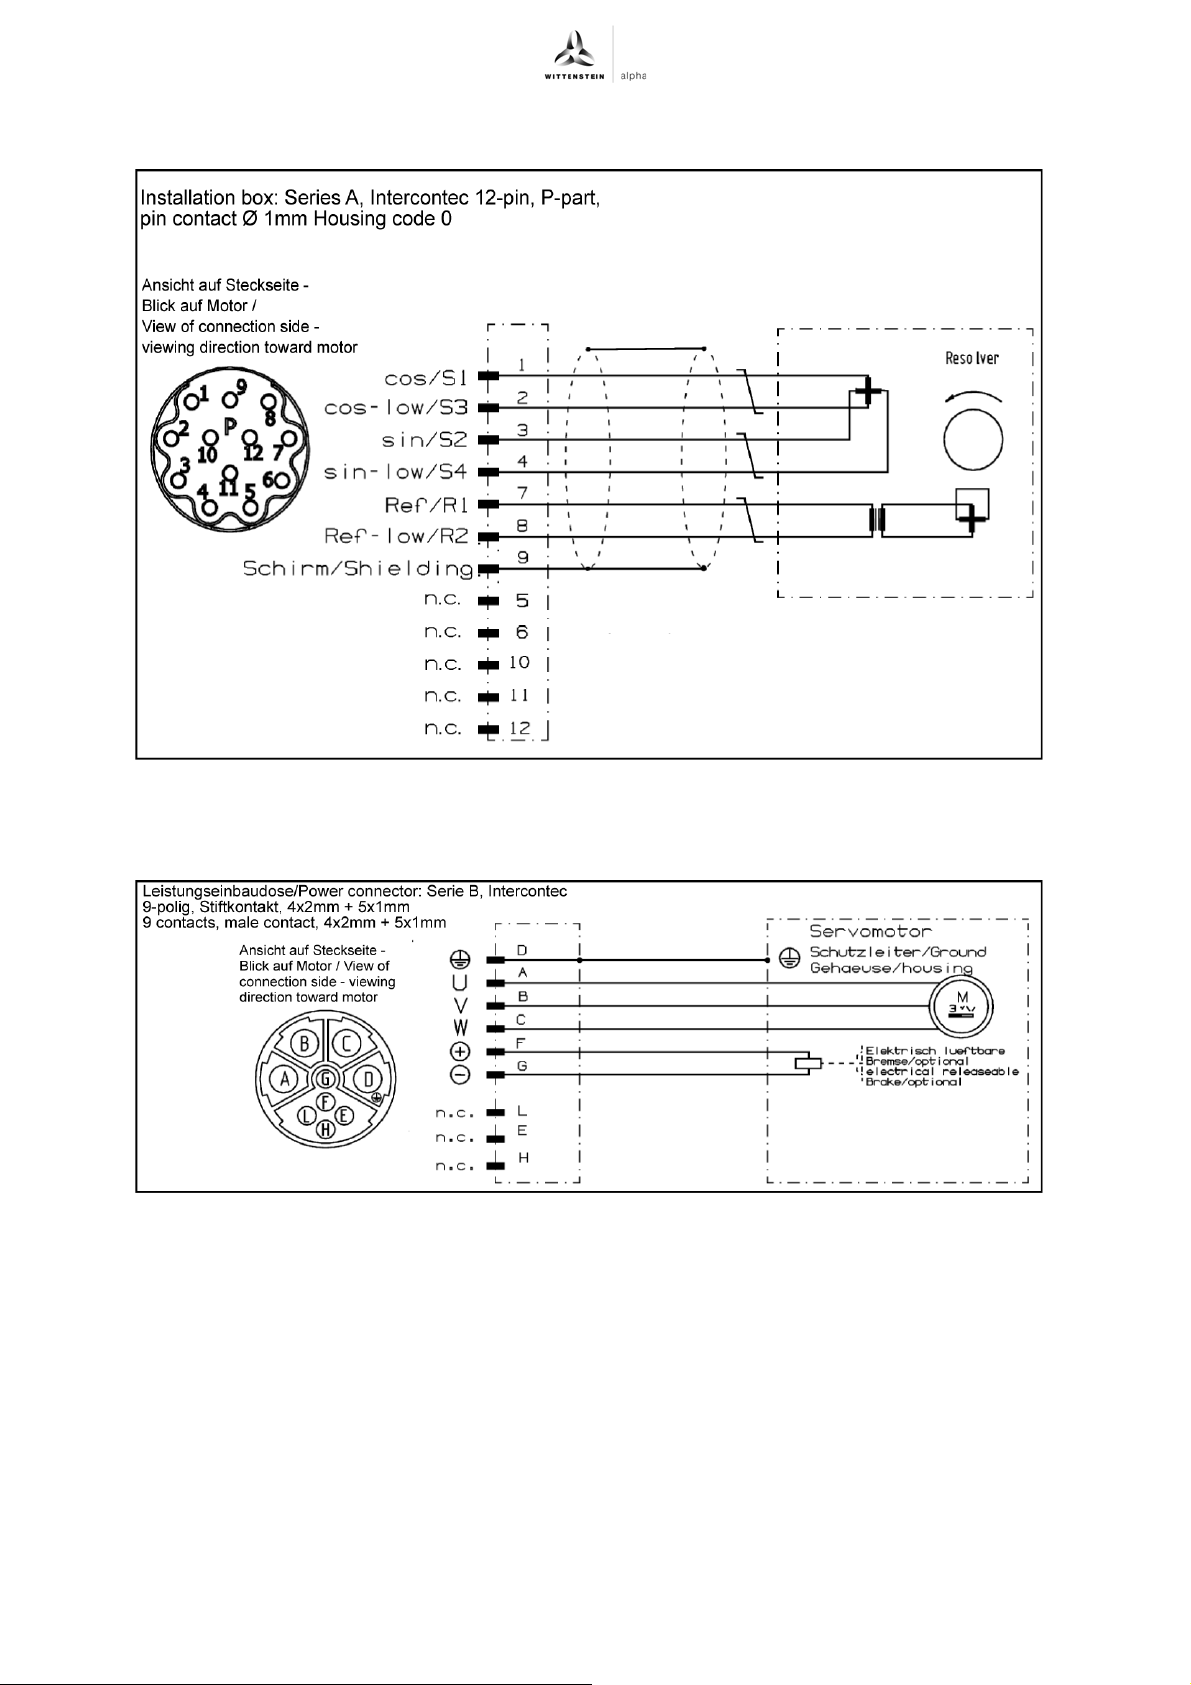
Appendix TPM
Option “R” —signal (pin assignment 4)
+
9.4.26 Pin assignment 5 TPM
Design with optical encoder —output (pin assignment 5)
+
dynamic
en-48 4022-D018396 Revision: 07
Page 49
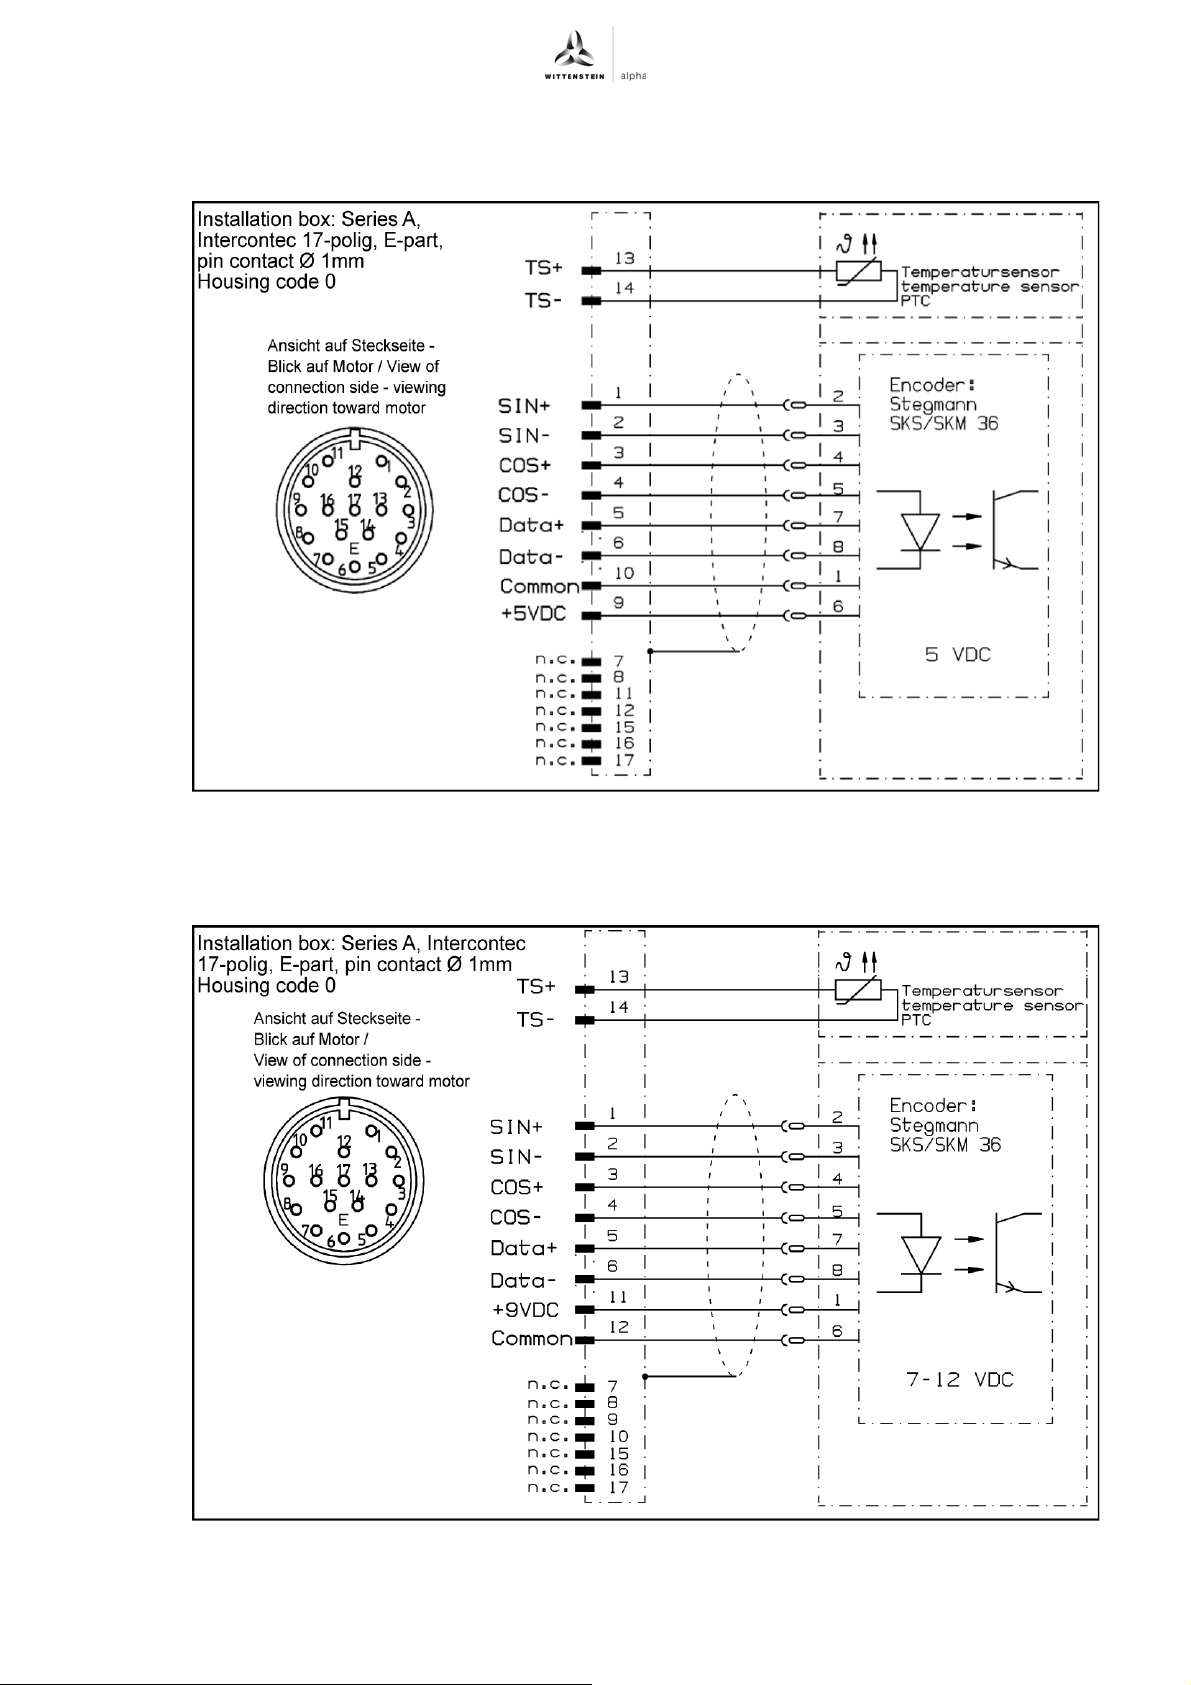
TPM
+
Option “E” and “V” with 320 V intermediate voltage —signal (pin assignment 5)
+
With TPM
dynamic product size 004, 010 and 025 with 320V intermediate voltage
Appendix
Option “E” and “V” with 560 V intermediate voltage —signal (pin assignment 5)
+
With TPM
voltages
dynamic product size 050 with 320V and all product sizes with 560V intermediate
Revision: 07 4022-D018396 en-49
Page 50
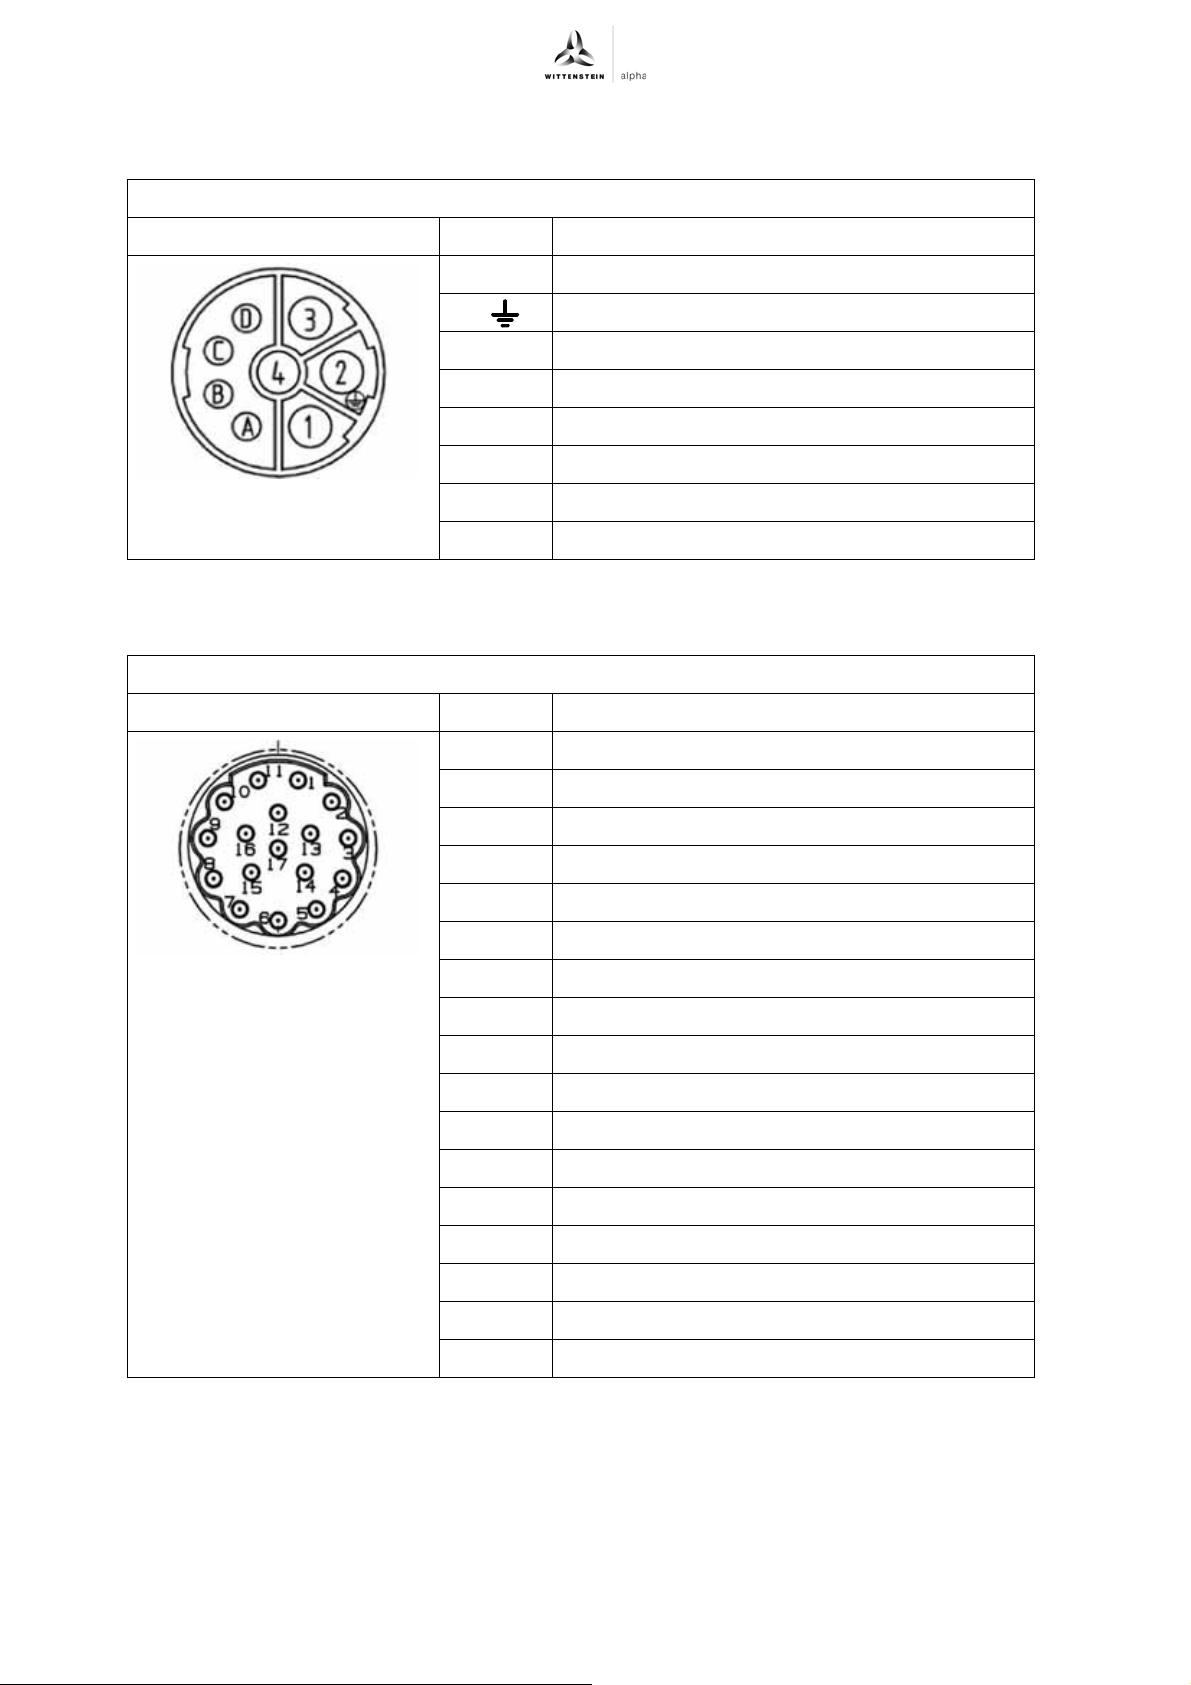
Appendix TPM
9.4.27 Pin assignment 6 Design with optical encoder — output (pin assignment 6)
Intercontec mounting socket, series production 923, 8-pin E, contact pin 4x2mm + 4x1mm
View of plug side of actuator Pin Function
1U
2 ( ) Earth conductor
3W
4V
A Temp +
B Temp C Brake + (optional)
D Brake - (optional)
Tbl-40: Design with optical encoder — output (pin assignment 6)
Option "S" and "M" — signal (pin assignment 6)
+
Intercontec mounting socket, series production 623, 17-pin E, contact pin Ø 1mm
View of plug side of actuator Pin Function
1 5V Sense
2n.c.
3n.c.
4 0V Sense
5n.c.
6n.c.
7 P-encoder / +5V
8clock
9*clock
10 M-encoder / 0V
11 n.c.
12 Ua2
13 *Ua2
14 data
15 Ua1
16 *Ua1
17 *data
Tbl-41: Option "S" and "M" — signal (pin assignment 6)
en-50 4022-D018396 Revision: 07
Page 51
+
TPM
9.4.28 Cable setup / Cable cross-section
For ambient temperatures up to +30 C, the following applies for cables acc. to DIN EN 60204:
Appendix
Continuous stall
Cable
current
0 –15 Aeff 4 x 1.5 mm
2
& 2 x 0.75 mm
15 –21 Aeff 4 x 2.5 mm2 & 2 x 1 mm
21 –36 Aeff 4 x 6 mm2 & 2 x 1.5 mm
36 –50 Aeff 4 x 10 mm2 & 2 x 1.5 mm2
2
50 –66 Aeff 4 x 16 mm
Tbl-42: Cable setup / Cable cross-section
& 2 x 1.5 mm2
2
2
2
Revision: 07 4022-D018396 en-51
Page 52
2022-D016962
:
01
enAC: XXXXXXXX 2022-D016962 Revision: 01
WITTENSTEIN alpha GmbH · Walter-Wittenstein-Straße 1 · 97999 Igersheim · Germany
Tel. +49 7931 493-12900 · [email protected]
WITTENSTEIN - one with the future
www.wittenstein-alpha.de
 Loading...