

Page 1
Operation, Installation and Service Manual
RUDDER
RUDDER
RUDDER
RUDDER
X
RUDDER
RUDDER
Rudder Angle Indicator System
05014-0128-01; 056357/B; 05 Oct 2017
Northrop Grumman Sperry Marine B.V. (Representative Office)
Woltmanstr. 19 • D-20097 • Hamburg, Germany
Tel.: +49-40-299 00-0 • Fax: +49-40-299 00-146 • E-mail: [email protected]
Page 2
056357/B RAIS
© 2017 Northrop Grumman Sperry Marine B.V.
This document and the information herein is and remains the intellectual property of Northrop
Grumman Sperry Marine B.V. [NGSM BV] and its associate companies and may not be copied,
reproduced or translated without the express permission of NGSM BV. A limited license is granted for the user to reproduce this documentation for his own internal use, but not for distribution
to third parties. Reproduction of this document for resale or commercial gain is expressly prohibited.
Specifications were correct at time of press but may be varied in accordance with NGSM BV’s
policy of continuous product development.
Any technical content should be verified with NGSM BV.
Sperry Marine, with major engineering and support offices in New Malden, England, and
Hamburg, Germany, is part of the Northrop Grumman Navigation & Maritime Systems Division
N&MSD.
Revision Record
Rev. Date Remarks
B 05 Oct 2017 updated release, RAIS system definition implemented, safety notes for
serial output and RS-422 output usage added
A 15 Jun 2009 initial release
Page 3
RAIS 056357/B
Contents
Chapter 1: Introduction
1.1 System Description................................................................................... 1-1
Intended Use ............................................................................................. 1-1
Not Intended Use ...................................................................................... 1-1
1.2 Design and Main Features........................................................................ 1-2
1.3 Principle of Operation ............................................................................... 1-3
1.4 RAIS Overview .......................................................................................... 1-4
System Components................................................................................. 1-4
1.5 RAIS Technical Data .................................................................................. 1-6
1.6 Declaration of Conformity........................................................................ 1-9
Chapter 2: Operation
2.1 Normal Operational Mode........................................................................ 2-1
Chapter 3: Alarms System
3.1 Alarm Indication........................................................................................ 3-1
Alarm Status Output ................................................................................. 3-1
Serial Data Alarm Output ......................................................................... 3-1
3.2 Alarm Numbers ......................................................................................... 3-3
3.3 Viewing RAC Errors through SUSI .......................................................... 3-5
Chapter 4: Scheduled Maintenance
4.1 Maintenance by Shipboard Personnel .................................................... 4-1
4.2 Maintenance by Service Personnel ......................................................... 4-1
Chapter 5: Installation
5.1 Mechanical Installation ............................................................................ 5-1
5.2 Electrical Installation ................................................................................ 5-1
Rudder Angle Calibrator ........................................................................... 5-1
Rudder Angle Feedback Unit Potentiometer........................................... 5-2
Chapter 6: System Configuration
6.1 Initial system configuration ..................................................................... 6-2
Configuring the RAC with SUSI ............................................................... 6-2
6.2 System Parameters................................................................................... 6-6
Feedback Type ........................................................................................... 6-7
Serial I/O..................................................................................................... 6-8
Relay Setup...............................................................................................6-11
iii
Page 4
056357/B RAIS
6.3 In- and Output Calibration...................................................................... 6-12
Input Calibration Table............................................................................ 6-14
Output Calibration Table ......................................................................... 6-14
General Remarks on Calibration ............................................................ 6-15
Initial Calibration ..................................................................................... 6-16
Adding, Editing and Deleting Calibration Points ..................................6-22
Input Calibration using Dummy Values.................................................6-24
Chapter 7: Troubleshooting
7.1 General Troubleshooting Instructions ..................................................... 7-1
Location of Parts on the Rudder Angle Calibrator PCB .......................... 7-2
Terminal Boards and Connectors............................................................. 7-2
Exchangeable Components...................................................................... 7-2
Diagnostic LEDs......................................................................................... 7-3
Chapter 8: Corrective Maintenance
8.1 Updating the RAC Firmware with SUSI .................................................. 8-1
8.2 Replacing Alarm Output Relays............................................................... 8-5
Appendix
A Setup and Configuration Tables
B Third party Documentation
C Drawings
iv
Page 5
RAIS 056357/B
DANGER
WAR NING
CAUTION
Note
DANGER
CAUTION
Safety Instructions
Safety Notice Conventions
The following safety notice conventions are followed throughout this
manual:
A Danger notice contains an operating or maintenance procedure, practice, condition, statement, etc., which, if not strictly observed, will
result in injury or death of personnel.
A Warning notice contains an operating or
maintenance procedure, practice, condition,
statement, etc., which, if not strictly observed,
could result in injury or death of personnel.
A Caution notice contains an operating or maintenance procedure, practice, condition, statement, etc., which, if not strictly observed, could
result in damage to, or destruction of equipment.
A Note contains an essential operating or maintenance procedure, condition or statement,
which is considered important enough to be
highlighted.
Special safety symbols may be used in this
manual to indicate:
Danger: Risk of electrical shock.
Used in conjunction with a Danger or Warning
notice.
Caution: Components are sensitive to electrostatic discharge.
Used in conjunction with a Caution notice.
v
Page 6
056357/B RAIS
CAUTION
CAUTION
Note
Note
Note
Note
Note
General Safety Information for the Operator
Risk of misusage
The ALR sentence as serial output of the RAC is not MED complaint and
therefore NOT allowed as system setting for a ship under wheelmark
certification.
Always make sure that the ALR sentence setting is INACTIVATED when
the RAC is used on a ship under wheelmark certification.
Risk of misusage
The RS-422 output 1 and RS-422 output 2 of the RAC is not
MED compliant in case 38400 baud are selected as interface setting.
Always make sure that another baud rate setting (4880 or 9600 baud)
must be selected as RS-422 output 1 and RS-422 output, when the RAC is
used on a ship under wheelmark certification
Regularly check the indication of the RAIs against the actual position of
the rudder angle shaft to make sure that calibration is applied properly
and the specified accuracy is maintained.
A given alarm system may employ reverse output logic (closed on
alarm). In this case, powering off the Rudder Angle Calibrator will not
raise an alarm.
For recording all parameter settings see “Setup and Configuration
Tables” in the appendix of this manual.
All content of the appended third party documentation is on behalf of the
owners of the documentation. Sperry Marine is not responsible and not
liable for any content of third party documentation.
In case of doubt, verify the content of third party documentation with the
owners of the documentation.
Sperry Marine Service:
In case of service refer to www.sperrymarine.com/offices for a list of
all Sperry Marine Offices and Service Agents worldwide.
vi
Page 7
RAIS 056357/B
DANGER
CAUTION
CAUTION
WAR NING
Note
WAR NING
General Safety Information for Service Personnel
Life danger through electrical shock
Certain alarm devices may operate with hazardous voltages, switched
by the alarm relay output contacts.
NEVER connect live wires to the unit’s terminals, when wiring up the
Rudder Angle Calibrator.
ALWAYS make sure that any external device or power supply to be connected to the alarm relay outputs is de-energized and safeguarded
against accidental switching-on.
Risk of damage of electrostatic-discharge-sensitive components
Components on the Rudder Angle Calibrator PCB are sensitive to static
discharge.
While wiring up the Rudder Angle Calibrator, take the necessary precautions to prevent electrostatic discharges.
Risk of damage of electrostatic-discharge-sensitive components
The
Rudder Angle Calibrator contains electrostatic sensitive components.
Electrostatic discharge may permanently damage components.
When configuring the
electrostatic discharge. Avoid touching any of the electronic circuitry.
Rudder Angle Calibrator, take precautions to prevent
Risk of personal injury
To calibrate the feedback input, the rudder has to be moved over its
entire range. Always make sure that the steering gear is operative and
that the rudder may be actuated safely without any risk of personal
injury or damage to equipment, especially when the vessel is drydocked
and works are carried out by shipyard personnel.
Always inform the shipboard or shipyard personnel in charge of your
intention to actuate the rudder and obtain permission to operate the
steering gear for calibration purposes, before moving the rudder.
The calibration procedures require that tasks are carried out at different
locations on the vessel.
If possible, use voice communication to instruct one or more helpers to
report the actual rudder angle indications as read from the rudder stock
scale and indicated at the RAIs respectively.
Risk of injury
Connecting the RAC to a rudder angle feedback unit in parallel with the
steering gear feedback loop bears the risk of malfunction of the steering
gear in case of wire breaks or short-circuits resulting in possible injury
and/or damage.
Under no circumstances must the RAC be connected to a rudder angle
feedback unit potentiometer in parallel with the steering gear feedback
loop.
vii
Page 8
056357/B RAIS
CAUTION
CAUTION
CAUTION
Note
Note
Risk of damage
As the feedback potentiometer supply voltage is provided by the Rudder
Angle Calibrator, connecting the RAC to a feedback potentiometer in parallel to any device other than a second Rudder Angle Calibrator bears the
A
risk of damage in case of wire breaks or short-circuits.
Never connect the RAC to a feedback potentiometer in parallel to any
device other than a second RAC.
Risk of misusage
The ALR sentence as serial output of the RAC is not MED complaint and
therefore NOT allowed as system setting for a ship under wheelmark
certification.
Always make sure that the ALR sentence setting is INACTIVATED when
the RAC is used on a ship under wheelmark certification.
Risk of misusage
The RS-422 output 1 and RS-422 output 2 of the RAC is not
MED compliant in case 38400 baud are selected as interface setting.
Always make sure that another baud rate setting (4880 or 9600 baud)
must be selected as RS-422 output 1 and RS-422 output, when the RAC is
used on a ship under wheelmark certification
Generally, it cannot be guaranteed that the Rudder Angle Calibrator’s
parameter settings are left intact during a firmware update.
Before updating firmware, record all parameter settings to be able to reenter them manually, if required.
Calibration settings will not be touched when updating the firmware.
For recording all parameter settings see “Setup and Configuration
Tables” in the appendix of this manual.
viii
Page 9
RAIS 056357/B
Chapter 1: Introduction
1.1 System Description
Intended Use
The Sperry Marine Rudder Angle Indicator System (RAIS) is a system for
electric rudder angle indication on maritime vessels and must be operated only from appropriately trained and educated personnel familiar
with all mandatory safety and operating procedures.
The Sperry Marine Rudder Angle Indicator System (RAIS) in total consists of the Rudder Angle Calibrator (RAC), a microprocessor-controlled
signal conditioning device for electric rudder angle indicators, a series
of Rudder Angle Indicators (RAI) and a series of Rudder Angle Feedback
Units (RAFU) including limit switches and lever linkages.
Not Intended Use
The Sperry Marine Rudder Angle Indicator System (RAIS) is designed
for marine purposes only and therefore not allowed to be used for the
navigation of inland water vessels and river boats.
The ALR sentence as serial output setting of the RAIS is not MED compliant and must therefore permanently be inactivated for all ships under
wheelmark certification.
The RS-422 output 1 and RS-422 output 2 of the RAC is not
MED compliant in case 38400 baud are selected as interface setting.
The 38400 Baud setting is therefore not allowed for all ships under
wheelmark certification and another baud rate setting (4880 or 9600
baud) must be selected.
System Description 1-1
Page 10
056357/B RAIS
Rudder Angle Calibrator
(RAC)
rudder angle
indicators
analogue out (6)
feedback signal in
feedback supply
rudder angle
feedback unit
RUDDER
X
serial data out
alarm status
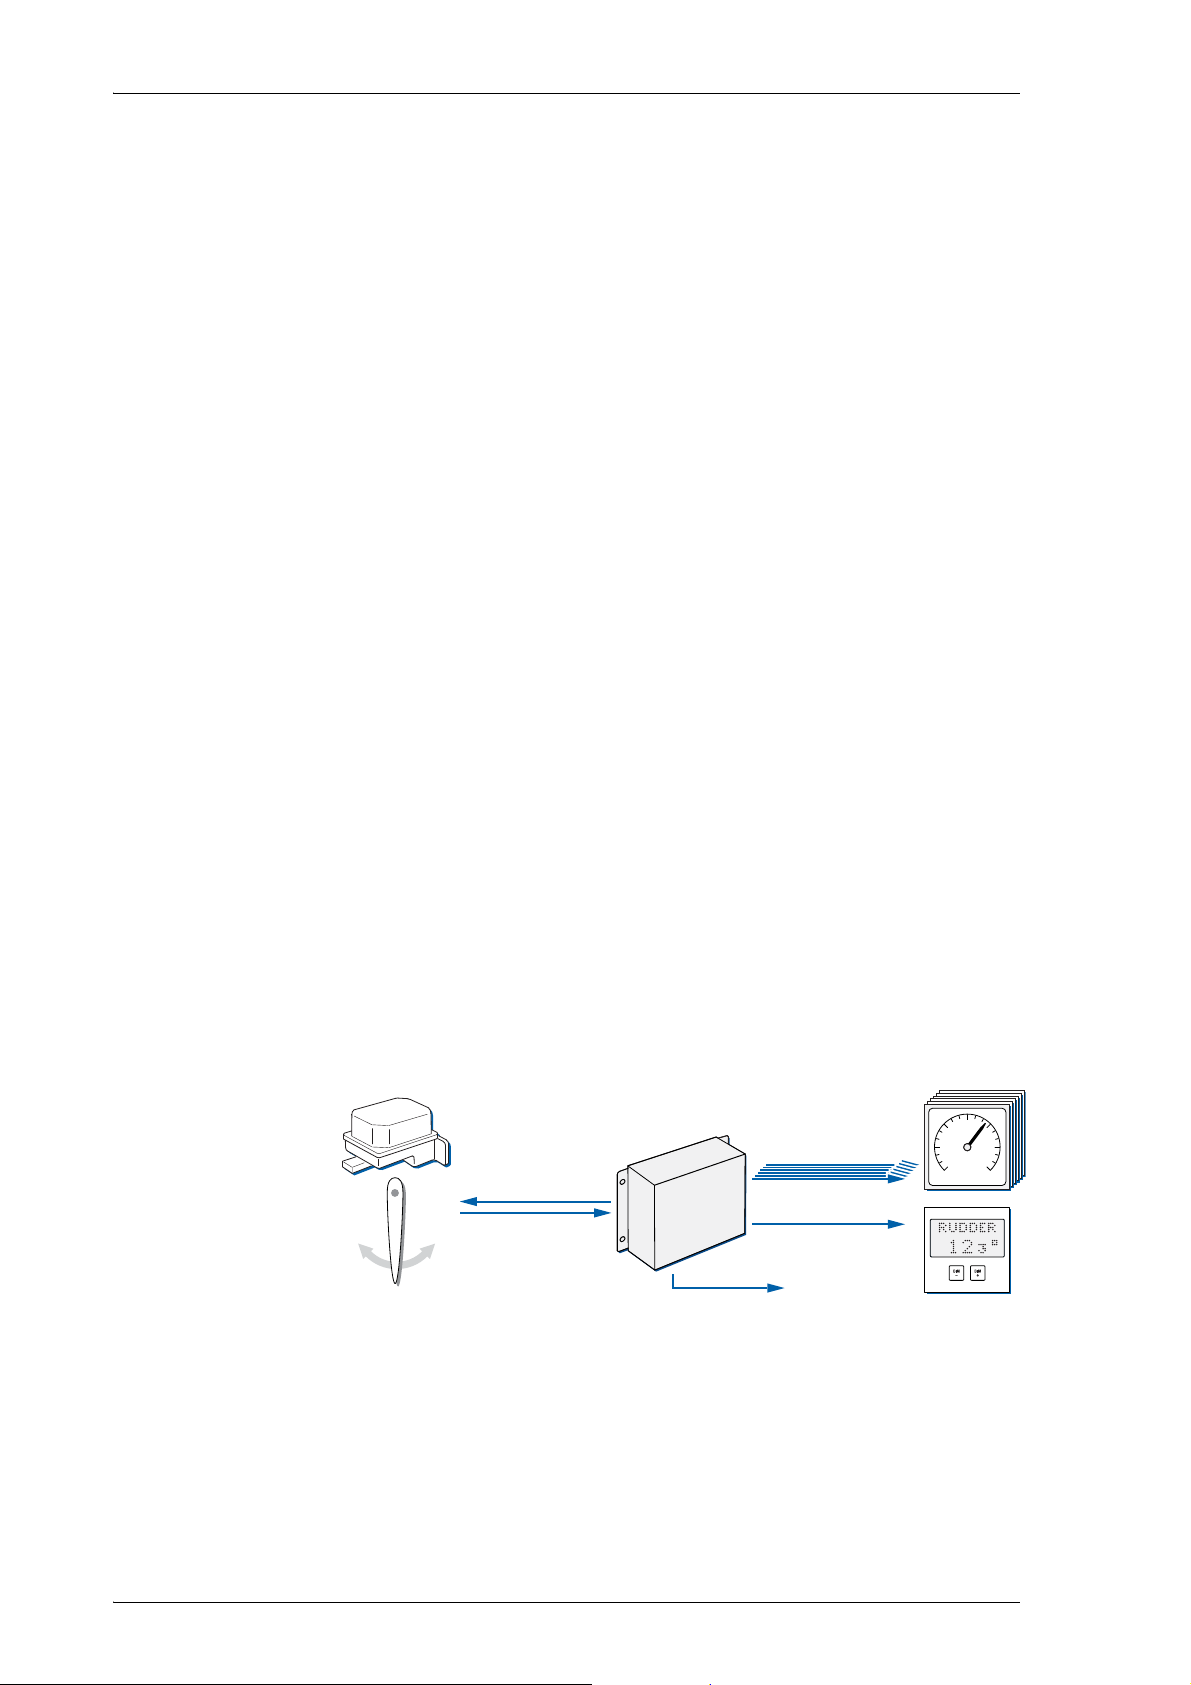
1.2 Design and Main Features
The Sperry Marine Rudder Angle Indicator System(RAIS) is a system for
electric rudder angle indication on maritime vessels.
The Rudder Angle Indicator System has been type approved by
DNV GL SE based on the
notification of the Federal Maritime and Hydrographic Agency of
Germany in compliance with the requirements of Marine Equipment
Directive (MED) 2014/90/EU of July 2014 as amended and is found to
comply with the requirements in the following specified regulations /
standards:
Regulation (EU) 2017/306, item No. MED/4.20.SOLAS 74 as amended,
Regulations V/18, V/19 & X/3
IMO Resolutions: A.694(17), MSC.36(63), MSC.97(73), MSC.191(79),
MSC.302(87)
and applicable to tests according:
(IEC 60945(2002) incl. corrigendum 1 (2008), IEC 61162series, ISO
20673(2007) and IEC 62288(2014)
Figure 1-1:
RAIS
Basic
with 1 RAC for
single-rudder system
and has been assigned certificate no. 47252-12 HH / 47253-12 HH.
For further details see “Declaration of Conformity” on page 1-9.
The RAC is used to attain ISO_20673 compliant overall calibration accuracy in RAI systems with conventional moving-coil indicators. It reads
the analogue signal from a rudder angle feedback unit and provides six
individually calibratable analogue signal outputs, and illumination supply terminals for the connected RAIs. To increase the number of available outputs, two RACs may be connected in parallel to one feedback
potentiometer.
The RAC also provides two calibrated rudder angle outputs in serial format using the $--RSA sentence according to IEC 61162 (NMEA 0183).
To alert the operator of power failure and other alarm conditions, the
RAC provides two status relay signal outputs and also transmits alarm
status data via the $--ALR sentence according to IEC 61162 (NMEA 0183).
1-2 Design and Main Features
Page 11
RAIS 056357/B
PORT
X X
STB
PORT
X X
STB
port side RAC stbd. side RAC
VDR
port + stbd.
rudder angles
Rudder Angle Calibrator (RAC)
data formatting
output calibration
input calibration
A/D conversion
D/A conversion
A
D
xy
D
A
xy
$...
RUDDER
X
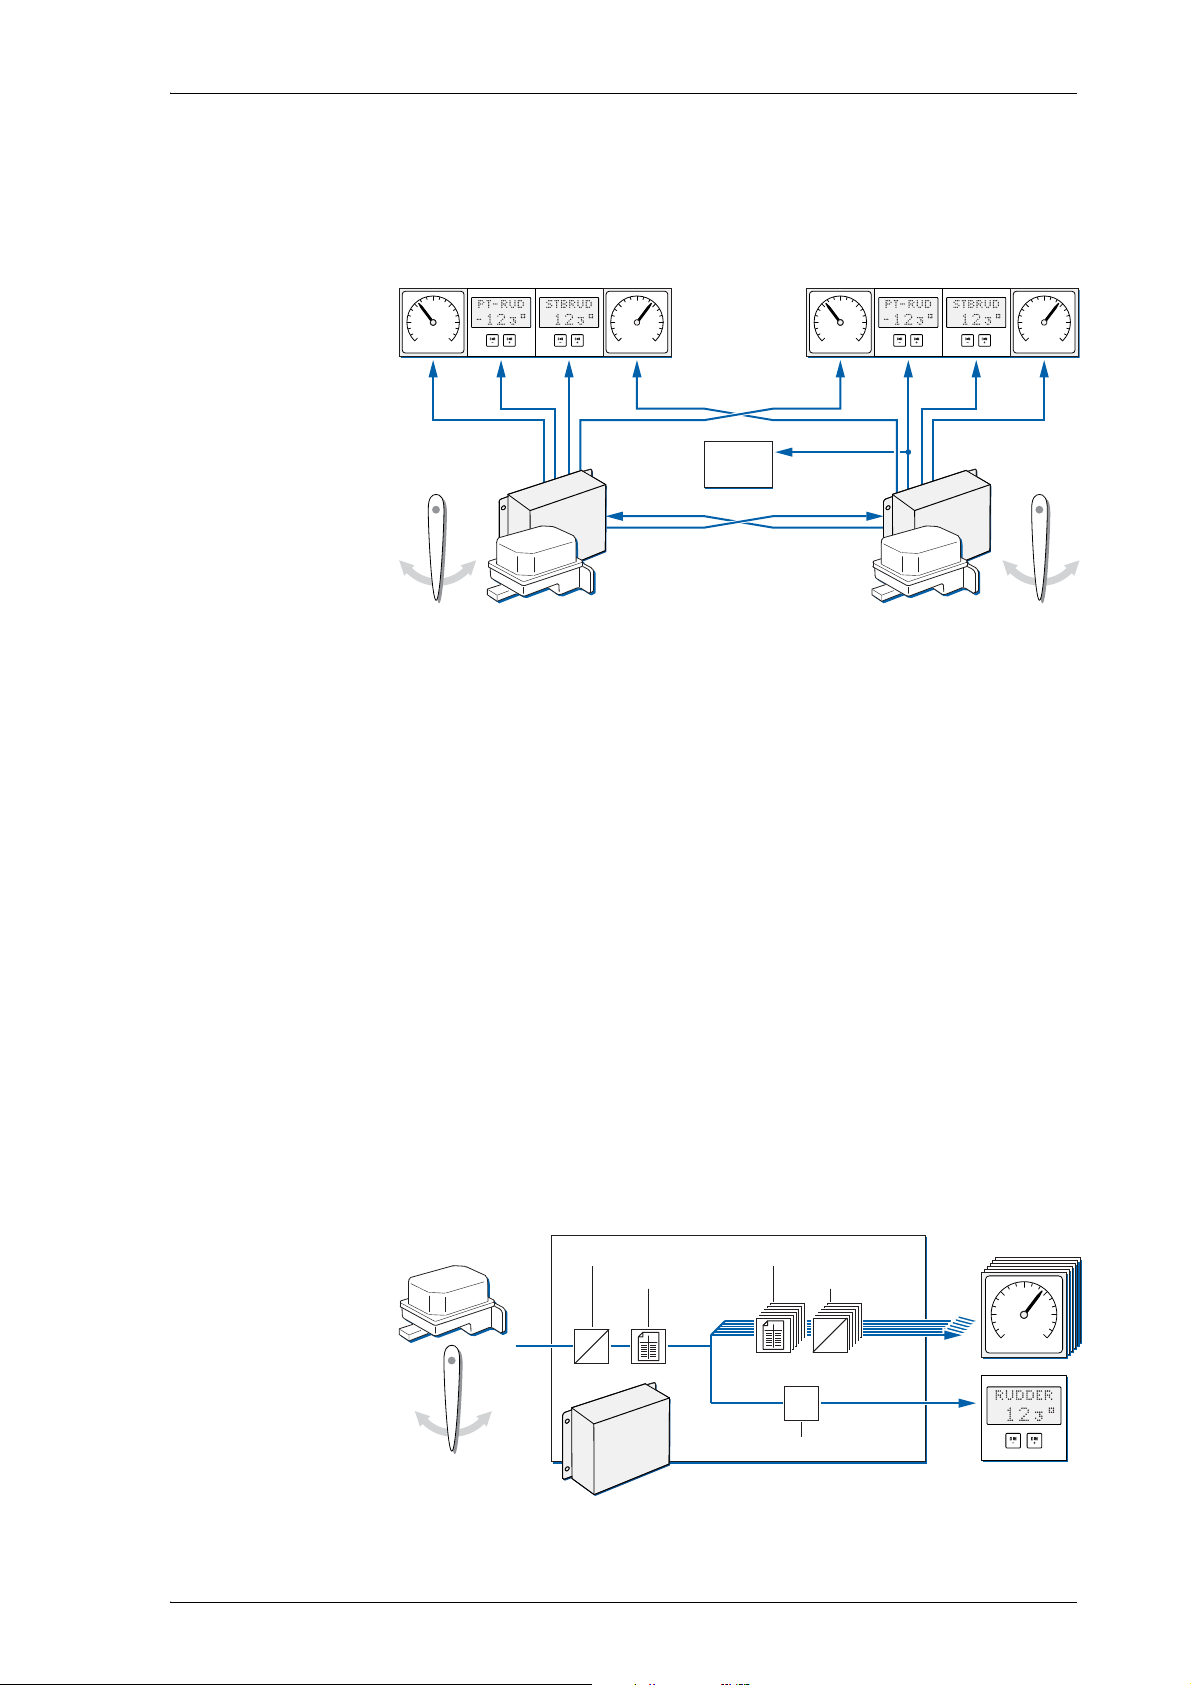
In dual-rudder systems, RACs for the port and starboard rudder are used
in a paired configuration. Each unit reads the feedback signal and drives
the analogue outputs for its own side. Through a crosslink, it also reads
the other unit’s digital output and produces a $--RSA sentence including
port and starboard rudder angles according to IEC 61162 (NMEA 0183).
Figure 1-2:
RAIS with 2 RACs for
d
ual-rudder system
1.3 Principle of Operation
Figure 1-3:
RAIS:
principle of operation
To attain an ISO 20673 compliant calibration accuracy for all RAIs connected, the RAC applies calibration as part of the A/D conversion of the
analogue feedback signal as well as of the D/A conversion for each analogue output.
An input calibration table maps the feedback input voltage to the corresponding rudder angle for a number of significant rudder positions.
The actual feedback voltage is thus converted to a digital rudder angle
value and automatically corrected according to the stored calibration
table. This compensates for possible misalignment of the feedback unit
and non-linearity of the feedback potentiometer.
The corrected digital value forms the reference for both the serial data
output and the subsequent conversion to the six separate analogue output voltages.
An output calibration table maps the digital rudder angle values to corresponding sets of analogue output voltages. This individually compensates for the non-linearity, range variation and zero-offset of the
connected RAIs.
Principle of Operation 1-3
Page 12
056357/B RAIS
03030
RUDDER
RUDDER
1.4 RAIS Overview
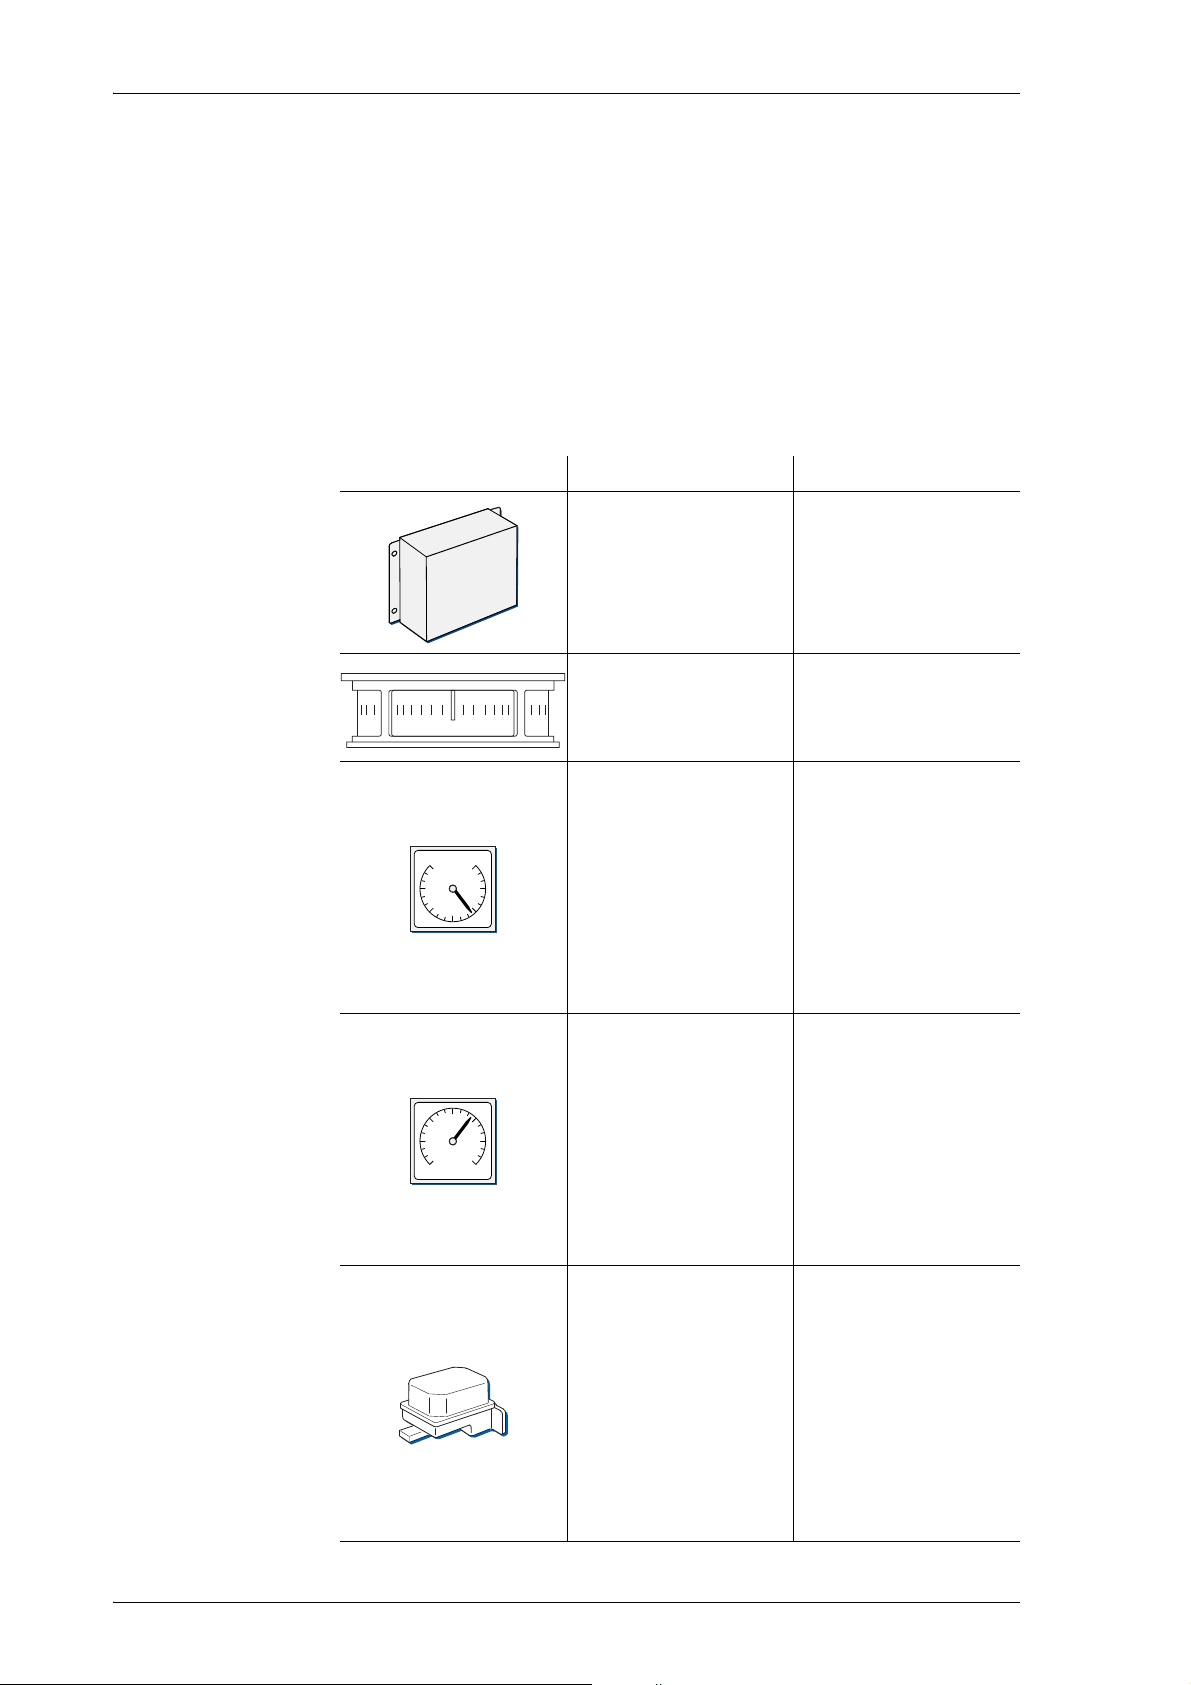
The Sperry Marine Rudder Angle Indicator System (RAIS) in total consists of the Rudder Angle Calibrator (RAC), a microprocessor-controlled
signal conditioning device for electric rudder angle indicators, a series
of different Rudder Angle Indicators RAI) types and a series of Rudder
Angle Feedback Units (RAFU) including limit switches and lever linkages.
System Components
Table 1-1:
RAIS system
components
System Component Name Stock No.
Rudder Angle Calibra-
074849-0000-000
tor (RAC), type 5014
RAI, third party, three
face panorama type,
(example)
060396-0000-000
(range ± 45°)
060397-0000-000
(range ± 70°)
RAI, standard type,
third party,
(example)
060327-0000-000
060328-0000-000
060334-0000-000
060335-0000-000
060338-0000-000
060339-0000-000
060352-0000-000
060353-0000-000
060357-0000-000
060359-0000-000
RAI, third party,
Panama type,
(example)
060325-0000-000
060326-0000-000
060331-0000-000
060337-0000-000
060332-0000-000
060362-0000-000
060340-0000-000
060341-0000-000
060354-0000-000
060355-0000-000
Rudder Angle Feedback Unit (RAFU);
type 4968-
074720-0000-000
074721-0000-000
074722-0000-000
074724-0000-000
074725-0000-000
074784-0000-000
074785-0000-000
074788-0000-000
074791-0000-000
074795-0000-000
074796-0000-000
1-4 RAIS Overview
Page 13
RAIS 056357/B
Note
System Component Name Stock No.
- Limit Switches (inside
074723-0000-000
RAFU housing, not
shown)
Lever Linkage 020508-0000-000
022501-0000-000
For all details regarding the Rudder Angle Indicators, refer to the third
party documentation from the supplier Faiveley Mors Smitt, as listed in
the appendix of this manual.
RAIS Overview 1-5
Page 14
056357/B RAIS
1.5 RAIS Technical Data
Environmental Requirements
ambient temperature, operation -15 °C – +55 °C
ambient temperature, storage -25 °C – +70 °C
protection grade IP 23 to DIN EN 60529
environmental conditions / EMC in accordance with IEC 60945,
equipment category “protected
from the weather”
Power Supply
RAC supply voltage 24 VDC
RAC max. ripple content - 10 – + 20% Vpp
RAC power consumption 3 W max.
Rudder Angle Indicator System
power consumption
RAC Magnetic Clearance
to standard magnetic compass 0.30 m
to steering magnetic compass 0.30 m
reduced, to standard magnetic compass 0.30 m
reduced, to steering magnetic compass 0.30 m
RAC Dimensions and Weight
width 230 mm
height 145 mm
depth 65 mm
weight 3.0 kg
RAFU Dimensions and Weight
15 W max. in total,
for rudder angle indicator illumination via RAC:
width 293 mm
height 200 mm
depth 192 mm
weight 7.5 kg
1-6 RAIS Technical Data
Page 15
RAIS 056357/B
CAUTION
RAC Signal and Data Inputs
rudder angle feedback input Wiper signal from rudder angle
feedback potentiometer;
±15 VDC supply voltage provided
by RAC.
RS-422 input NMEA 0183 / IEC 61162;
other side’s rudder angle in dual
rudder systems ($--RSA)
RAC Signal, Data and Status Outputs
analogue rudder angle outputs
(6x)
six independently calibratable
voltage outputs to moving-coil
rudder angle indicators,
±15 VDC max. into 10 k
RS-422 output 1 IEC 61162 (NMEA 0183),
4800
9600 or
38400 Baud*
rudder sensor angle ($--RSA)
RS-422 output 2 IEC 61162 (NMEA 0183);
4800
9600 or
38400 Baud*
rudder sensor angle ($--RSA),
set alarm state ($--ALR)
Risk of misusage
The RS-422 output 1 and RS-422 output 2 of the RAC is not
MED compliant in case 38400 baud are selected as interface setting.
Always make sure that another baud rate setting (4880 or 9600 baud)
must be selected as RS-422 output 1 and RS-422 output, when the RAC is
used on a ship under wheelmark certification
“Power Fail. / Gen. Alarm” output opto-isolated solid state relay;
peak off-state voltage 100 V
AC/DC, on-state current 100mA,
on-state resistance < 25,
isolation voltage 1500 Vrms;
configurable as NO or NC contact,
open if power off
“Spare” relay output
(for future use)
opto-isolated solid state relay;
peak off-state voltage 100 V
AC/DC, on-state current 100mA,
on-state resistance < 25,
isolation voltage 1500 Vrms;
configurable as NO or NC contact,
open if power off
RAIS Technical Data 1-7
Page 16
056357/B RAIS
RAC Service I/O Port
USB service port Connects to a Windows host PC
through a vendor-specific USB
communications device class
driver. The Rudder Angle Calibrator is accessed via the “SUSI”
application, using a proprietary
data protocol.
1-8 RAIS Technical Data
Page 17
RAIS 056357/B
Note
1.6 Declaration of Conformity
Marine Equipment Directive EC Declaration of Conformity:
Northrop Grumman Sperry Marine B.V.
Woltmanstrasse 19
D-20097 Hamburg, Germany.
as manufacturer hereby declares that the following specified equipment:
„Sperry Marine Rudder Angle Indicator System“
complies with the Marine Equipment Directive (MED) 2014/90/EU of July
2014 as amended, as
„Rudder Angle Indicator“ (RAI)
This equipment has been tested to verify compliance with the
Regulations and Testing Standards according to implementing regulation (EU) 2017/306 as per EC - Type Examination Certificate (Module B)
and QS - Certificate of Assessment -EC (Module D):
Notified Body No. 0098 DNV GL SE based on the notification of the Federal Maritime and Hydrographic Agency of Germany.
The current issue of the detailed Marine Equipment Directive EC Declaration of Conformity of Northrop Grumman Sperry Marine B.V. Hamburg
is part of the client CD stock no. 56 800.
For further details please contact:
Northrop Grumman Sperry Marine B.V. Hamburg
Regulatory Support Group
Declaration of Conformity 1-9
Page 18
056357/B RAIS
1-10 Declaration of Conformity
Page 19
RAIS 056357/B
Note
Note
Chapter 2: Operation
The RAC possesses no user-accessible controls. Once installed and
properly configured, it will take up operation unattended, as soon as
power is applied to the RAIS.
Likewise, no special procedures need to be followed to power off the
system. The RAC may be safely switched off at any time and will reboot
into normal operational mode as soon as it is switched on again.
2.1 Normal Operational Mode
When power is applied, the RAC boots up and enters the normal operational mode within a few seconds.
The unit applies in- and output calibration according to the stored calibration tables at all times.
If no errors are present, the only noticeable effect of the RAC being
included in the RAIS, will be an increased accuracy in comparison to
conventional systems.
Regularly check the indication of the RAIs against the actual position of
the rudder angle shaft to make sure that calibration is applied properly
and the specified accuracy is maintained.
To alert the operator when the RAC is powered off or an alarm condition
is present, in most installations, the “Power Fail. / Gen. Alarm” relay will
be connected to an alarm indicator or central alarm panel.
A given alarm system may employ reverse output logic (closed on
alarm). In this case, powering off the RAC will not raise an alarm.
Normal Operational Mode 2-1
Page 20
056357/B RAIS
2-2 Normal Operational Mode
Page 21
RAIS 056357/B
CAUTION
Note
Chapter 3: Alarms System
Risk of misusage
The ALR sentence as serial output of the RAC is not MED complaint and
therefore NOT allowed as system setting for a ship under wheelmark
certification.
Always make sure that the ALR sentence setting is INACTIVATED when
the RAC is used on a ship under wheelmark certification.
3.1 Alarm Indication
The RAC does not contain built-in audible or visible alarm indicators.
To indicate the presence of an alarm, the alarm status output must be
connected to an external device, such as an alarm buzzer or a central
alarm unit, or the RAC must be configured to transmit the alarm state to
an IEC 61162 (NMEA 0183) compliant serial data alarm handling facility.
Alarm Status Output
The “Power Fail. / Gen. Alarm” relay output signals the current alarm
state via a potential-free relay contact pair
In case the RAC raises an alarm, the output changes from the “no
alarm” to the “active alarm” state.
The output’s logic behaviour may be independently configured as NO
(normally open, closed on alarm) or NC (normally closed, open on
alarm). If the RAC is powered off, the output contacts are open.
The operator cannot actively reset the outputs from the “active alarm” to
the “no alarm” state. The outputs will only return to the “no alarm” state
when no alarm condition is present any more.
1
.
Serial Data Alarm Output
The RS-422 output 2 may be configured to transmit alarm status information using the $--ALR sentence according to IEC 61162 (NMEA 0183).
When the RAC raises an alarm, an $--ALR sentence is transmitted, containing the corresponding alarm number and description text. The alarm
will be marked as “active” and “not acknowledged”.
When a given alarm condition is no longer present, the RAC transmits
the respective $--ALR sentence once, with the status set to ”acknowledged”. The unit then stops transmitting the sentence in question.
When no active alarms are present, the RAC cyclically transmits a “no
alarms” message as recommended in IEC 80/520/INF. This is an $--ALR
sentence with null fields for the alarm code and description.
1. A second relay output is provided for future use (“Spare” output), which currently behaves identical to the “Power Fail. / Gen. Alarm” output. However,
this output may be assigned a different functionality in future software
releases.
Alarm Indication 3-1
Page 22
056357/B RAIS
Note
The RAC does not support remote alarm acknowledgement via the
$--ACK sentence. Alarms will be transmitted as being “not acknowledged”, even if acknowledged locally at the receiving end.
3-2 Alarm Indication
Page 23
RAIS 056357/B
Note
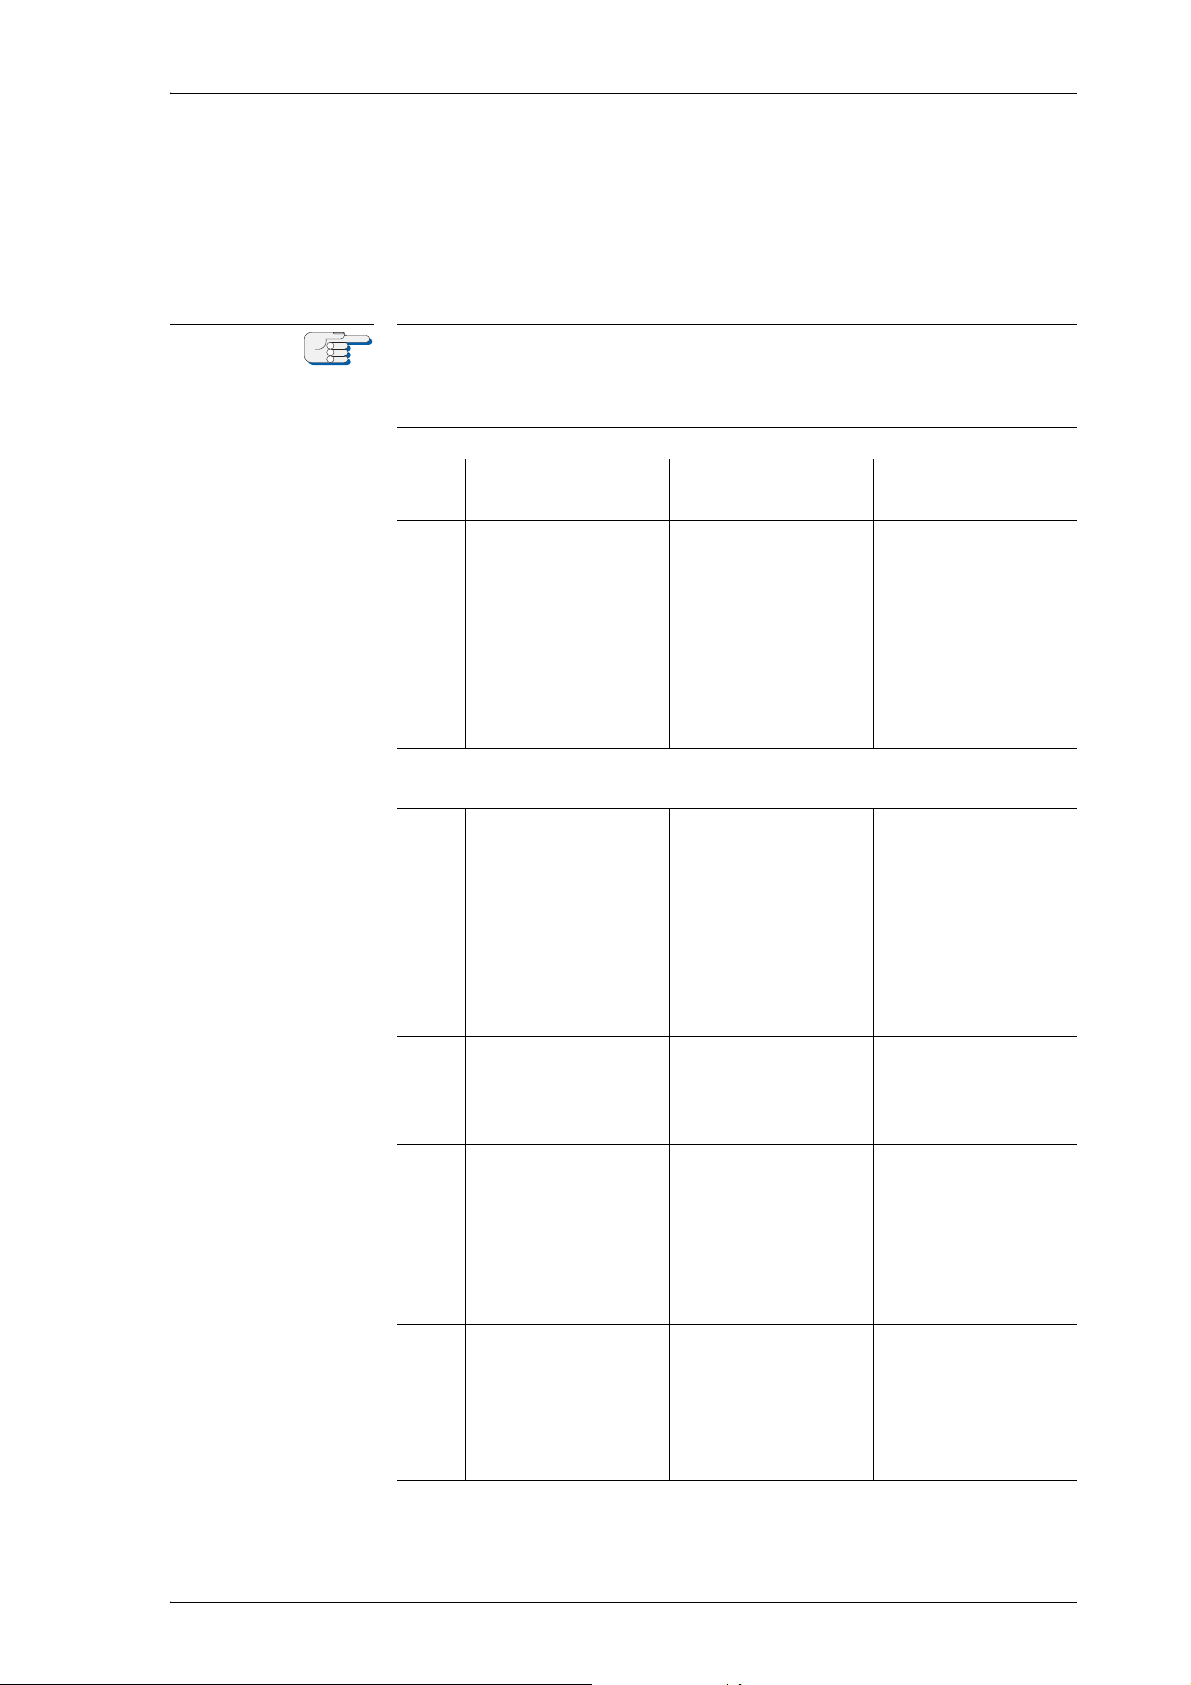
3.2 Alarm Numbers
If the RAC is configured to transmit the $--ALR sentence according to
IEC 61162 (NMEA 0183), the type of an active alarm may be determined
in more detail from the alarm number and description text contained in
the sentences transmitted.
Currently, $--ALR sentences are only generated in case of data I/O errors.
If the RAC exhibits malfunction without generating a corresponding
$--ALR sentence, contact Sperry Marine Service (Net) for troubleshooting
assistance.
Table 3-1:
RAC alarm numbers
Error IDError Text Cause Corrective Action
none
group 400: data I/O errors (NMEA crosslink between starboard and
port RACs in dual rudder system)
401 "wrong checksum
none $--ALR sentences
with null fields for
the code and description are “no
alarm” messages.
These are sent cyclically when no active alarm is
present.
faulty checksum in
(RxD1)"
NMEA sentence received at the
RS-422 input.
none
If error occurs only
occasionally, no action required.
If error occurs frequently, check
proper function of
other side’s RAC;
check connection
between RACs.
405 "data error (RxD1)" faulty data in
NMEA sentence received at the
RS-422 input.
410 "overrun error
(RxD1)"
415 "com port error
(RxD1)"
Alarm Numbers 3-3
RS-422 input receive buffer overrun
internal error accessing RS-422 input port
Check proper function of other side’s
RAC; check connection between RACs.
Check function and
configuration of
other side’s RAC
(baud rate, selected sentences);
check connection
between RACs.
Cycle power to restart RAC. If error
persists, contact
Sperry Marine Service (Net) for assistance.
Page 24
056357/B RAIS
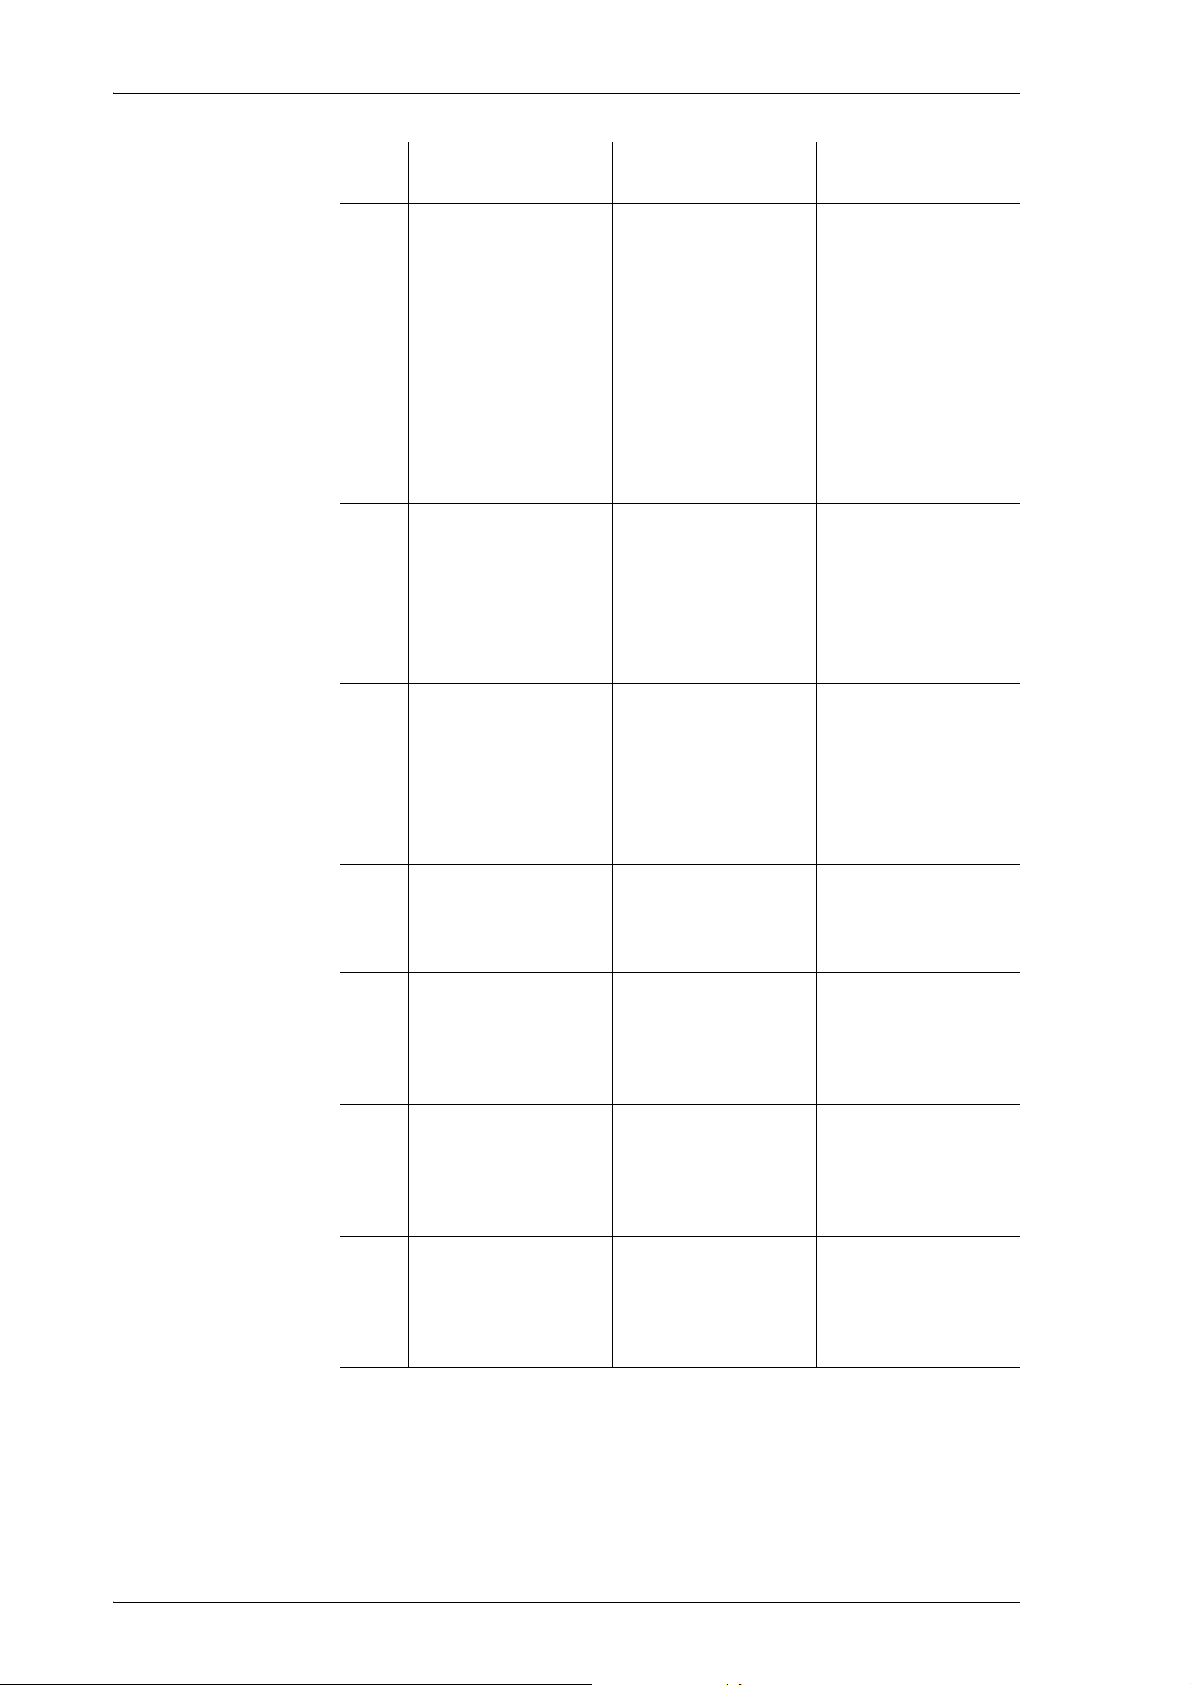
Error IDError Text Cause Corrective Action
430 "no nmea message
received (RxD1)"
435 "wrong sentence id
received (RxD1)"
440 "wrong talker id re-
ceived (RxD1)"
expected NMEA
sentences not received
wrong NMEA sentence type received
at the RS-422 input
wrong NMEA talker
ID received at the
RS-422 input
If RAC is not used in
dual rudder system,
disable the RS-422
input.
In dual rudder system, check configuration of other
side’s RAC (baud
rate, selected sentences); check connection between
RACs.
Check the type of
data source at the
RS-422 input. Only
other side’s RAC in
dual rudder system
may be connected
to the input.
Check the type of
data source at the
RS-422 input. Only
the other side’s RAC
in a dual rudder
system may be
connected to input.
445 "error in received
NMEA message"
480 "no RSA message
received"
481 "no starboard rud-
der received"
482 "no port rudder re-
ceived"
malformed NMEA
sentence received
at the RS-422 input
no NMEA $--RSA
sentence received
at the RS-422 input
received $--RSA
sentence does not
contain starboard
rudder
received $--RSA
sentence does not
contain port rudder
Check function of
other side’s RAC;
check connection
between RACs.
Check configuration of other side’s
RAC ($--RSA transmission must be
enabled).
Check that both
RACs are assigned
correctly to sides;
check function of
transmitting RAC.
Check that both
RACs are assigned
correctly to sides;
check function of
transmitting RAC.
3-4 Alarm Numbers
Page 25
RAIS 056357/B
3.3 Viewing RAC Errors through SUSI
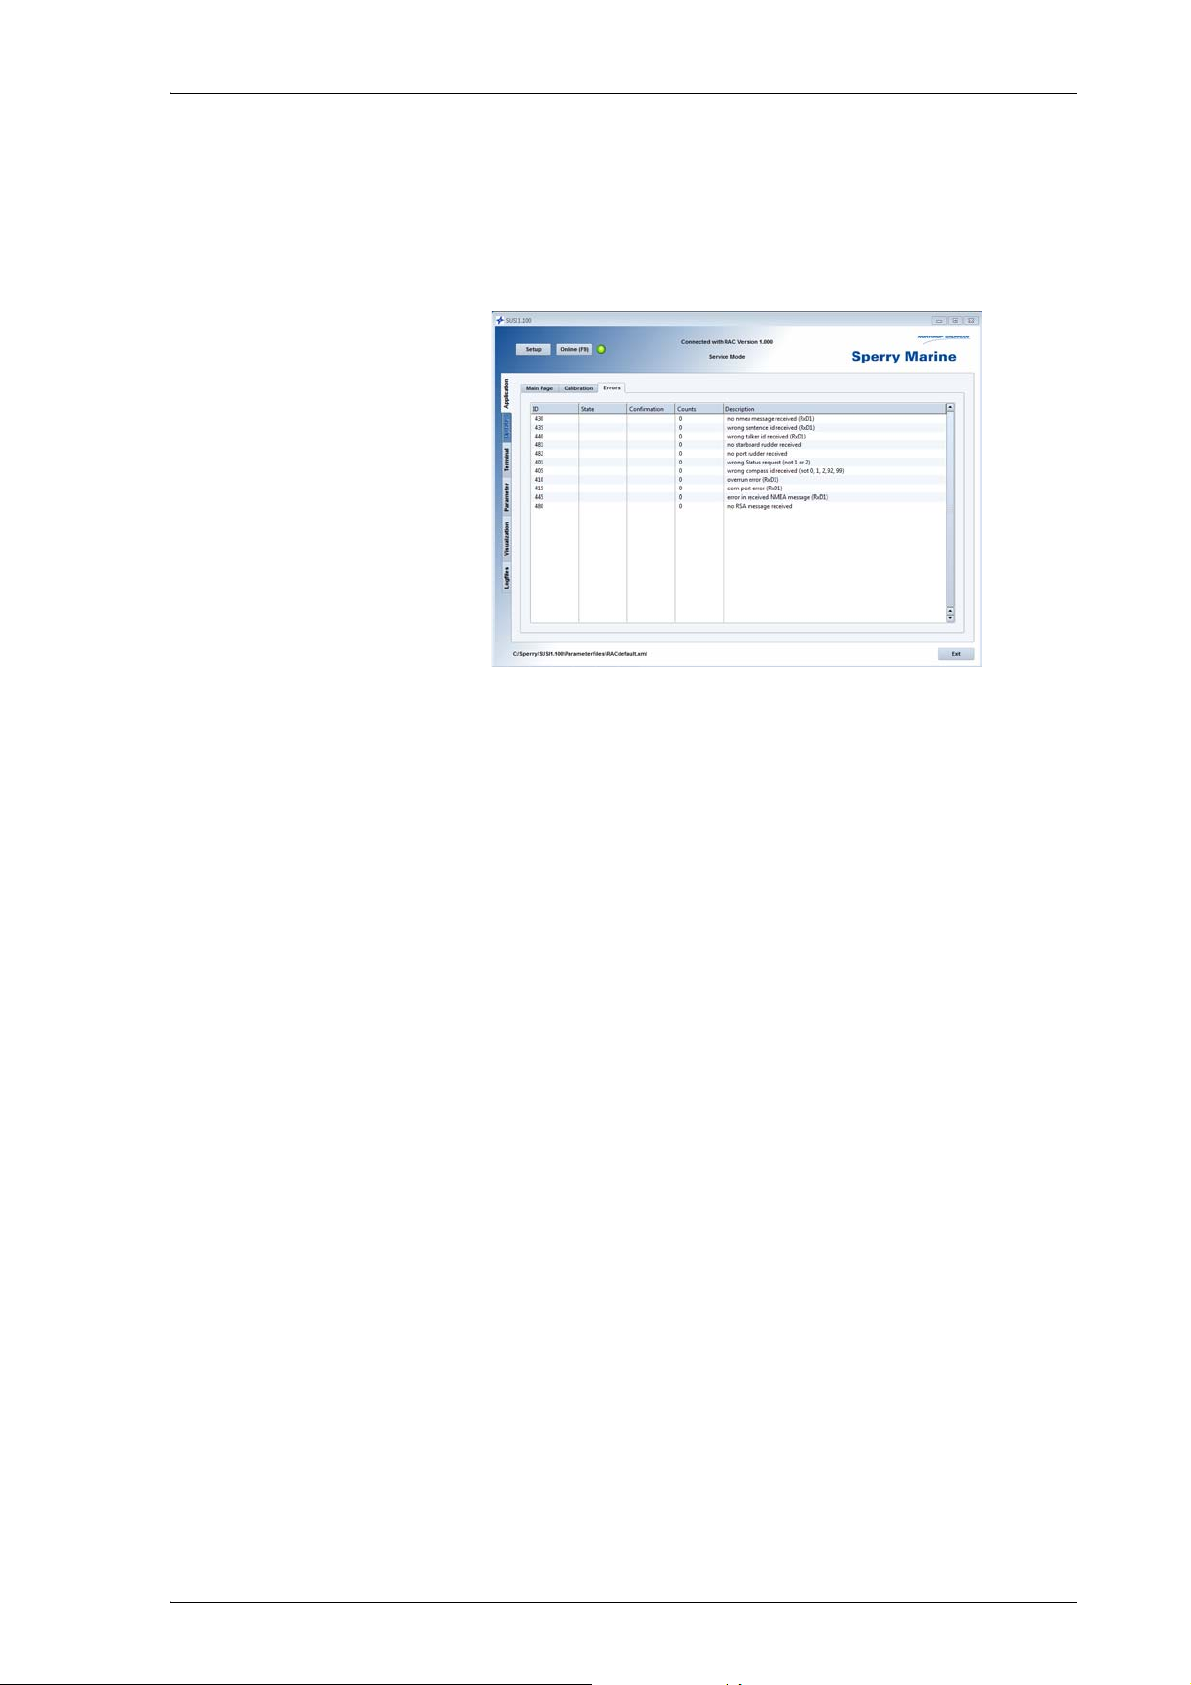
When connected to the RAC, the Sperry Universal Service Instrument
application (SUSI) provides an “Errors” page which displays current
state and counts the occurrence of the alarms listed in table
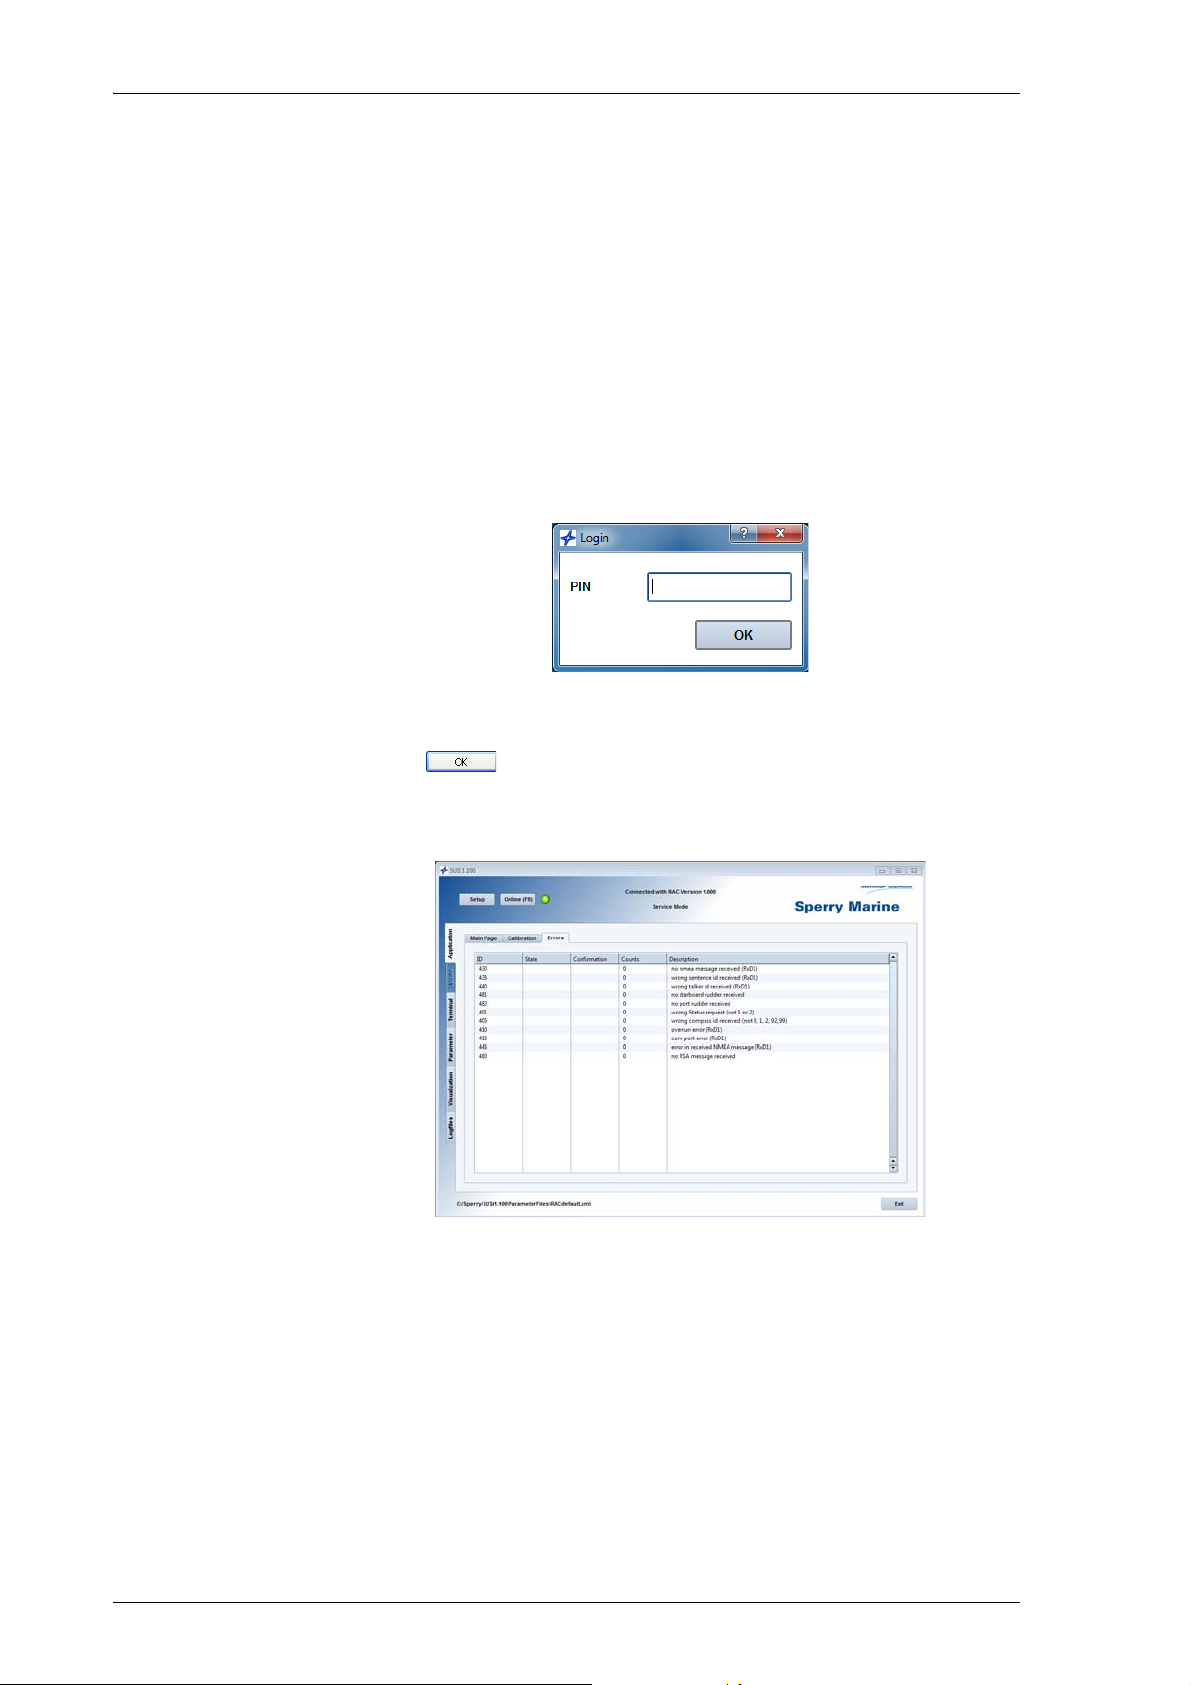
Figure 3-1:
SUSI’s Error Page
for the RAC
3-1 above:
For more information on the SUSI application, refer to chapter 6 (System Configuration) and to the SUSI Installation Guide included in the
appendix of this manual.
Viewing RAC Errors through SUSI 3-5
Page 26
056357/B RAIS
3-6 Viewing RAC Errors through SUSI
Page 27
RAIS 056357/B
Note
Chapter 4: Scheduled Maintenance
4.1 Maintenance by Shipboard Personnel
The RAC is a solid-state electronic device and contains no consumable
parts. Therefore, no set maintenance schedule to be carried out by
shipboard personnel or service personnel is required.
The housing should be kept clean and a regular visual inspection of
cables and connectors should be carried out to detect any signs of
damage or deterioration.
Should the RAC fail to attain the required calibration accuracy,
thoroughly check the cables for mechanical damage. Check the
connectors at the RAC, the rudder angle feedback unit and the RAIs for
signs of corrosion, loose contacts etc. Inspect the feedback unit and the
feedback linkage in particular for any signs of mechanical damage or
wear. In case the RAC does still fail to attain the required calibration
accuracy, maintenance by authorized service personnel is required.
4.2 Maintenance by Service Personnel
If re-calibration of the RAC is required, field service attendance must be
requested from Sperry Marine directly or through an authorized Sperry
Marine service representative.
The RAC is re-calibrated using the Sperry Universal Service Instrument
(SUSI). This tool is provided to authorized service personnel only and is
generally not available to end-customers.
Maintenance by Shipboard Personnel 4-1
Page 28
056357/B RAIS
4-2 Maintenance by Service Personnel
Page 29
RAC 056357/B
DANGER
CAUTION
Chapter 5: Installation
5.1 Mechanical Installation
The RAC is to be installed at a protected location. In most cases, it will
be placed inside a bridge console or bulkhead mounted in the vicinity of
the connected RAIs.
Attach the RAC to a level surface with four M6 screws (or nuts and
bolts). For the dimensions of the housing, refer to dimension drawing
5014-0112-01.
When not installed in a bridge console, the RAC is to be mounted
vertically (bulkhead mounting), with the cable inlets facing down.
Inside a bridge console, the RAC may be installed vertically, horizontally
or inclined.
5.2 Electrical Installation
Rudder Angle Calibrator
Wire up the system according to the connection diagrams and other
relevant documents provided.
Life danger through electrical shock
Certain alarm devices may operate with hazardous voltages, switched
by the alarm relay output contacts.
NEVER connect live wires to the unit’s terminals, when wiring up the
Rudder Angle Calibrator.
ALWAYS make sure that any external device or power supply to be connected to the alarm relay outputs is de-energized and safeguarded
against accidental switching-on.
Risk of damage of electrostatic-discharge-sensitive components
Components on the Rudder Angle Calibrator PCB are sensitive to static
discharge.
While wiring up the RAC, take the necessary precautions to prevent electrostatic discharges.
Mechanical Installation 5-1
Page 30
056357/B RAC
WAR NING
CAUTION
Rudder Angle Feedback Unit Potentiometer
Risk of injury
Connecting the Rudder Angle Calibrator to a rudder angle feedback unit
in parallel with the steering gear feedback loop bears the risk of malfunction of the steering gear in case of wire breaks or short-circuits resulting
in possible injury and/or damage.
Under no circumstances must the RAC be connected to a rudder angle
feedback unit potentiometer in parallel with the steering gear feedback
loop.
Risk of damage
As the feedback potentiometer supply voltage is provided by the Rudder
Angle Calibrator, connecting the RAC to a feedback potentiometer in par-
A
allel to any device other than a second RAC bears the risk of damage in
case of wire breaks or short-circuits.
Never connect the RAC to a feedback potentiometer in parallel to any
device other than a second RAC.
Generally, a dedicated rudder angle feedback unit will be installed for
the RAC. Alternatively, one or more RACs may use a separate
potentiometer in a feedback unit which also contains potentiometers
for, e. g., other RAI systems or the VDR.
5-2 Electrical Installation
Page 31
RAIS 056357/B
DANGER
WAR NING
Note
CAUTION
Note
Chapter 6: System Configuration
Life danger through electrical shock
Certain alarm devices may operate with hazardous voltages, switched
by the alarm relay output contacts.
During configuration, the Rudder Angle Calibrator must be operated
with the housing open. Make sure that any external device or power
supply connected to the alarm relay outputs is de-energized and safeguarded against accidental switching-on.
Risk of personal injury
To calibrate the feedback input, the rudder has to be moved over its
entire range. Always make sure that the steering gear is operative and
that the rudder may be actuated safely without any risk of personal
injury or damage to equipment, especially when the vessel is drydocked
and works are carried out by shipyard personnel.
Always inform the shipboard or shipyard personnel in charge of your
intention to actuate the rudder and obtain permission to operate the
steering gear for calibration purposes, before moving the rudder.
The calibration procedures require that tasks are carried out at different
locations on the vessel.
If possible, use voice communication to instruct one or more helpers to
report the actual rudder angle indications as read from the rudder stock
scale and indicated at the RAIs respectively.
Risk of damage of electrostatic-discharge-sensitive components
The
Rudder Angle Calibrator contains electrostatic sensitive components.
Electrostatic discharge may permanently damage components.
When configuring the
Rudder Angle Calibrator, take precautions to prevent
electrostatic discharge. Avoid touching any of the electronic circuitry.
This chapter is intended for authorized service personnel configuring or
servicing the Rudder Angle Calibrator. These tasks require a PC running
the Sperry Universal Service Instrument (SUSI) application.
SUSI is provided to authorized service personnel only and is generally
not available to end-customers.
The RAC must be configured and calibrated before it can be put into
operation. This is done from a PC (field engineer’s laptop or notebook
computer) connected to the RACs USB service port, running the Sperry
Universal Service Instrument application (SUSI).
The present chapter assumes that you have successfully installed SUSI
and the Rudder Angle Calibrator USB device driver on your PC. If you
have not yet installed the SUSI and/or the device driver, refer to the separate SUSI Installation Guide for Field Service Personnel, doc no 056358.
The procedures described below are performed using the RAC application controls inside SUSI’s application tab.
More advanced configuration features, accessible through SUSI’s terminal and parameter tabs, are beyond the scope of this manual.
6-1
Page 32
056357/B RAIS
6.1 Initial system configuration
Configuring the RAC with SUSI
1. If the RAC is currently powered up, switch off the power first.
2. Open the RAC housing and locate the USB service port receptacle,
J3, on the PCB. Make sure that the port is freely accessible for plugging and unplugging the USB cable. Do not plug in the cable yet.
3. Power up the RAC.
4. At the PC, start up the SUSI application.
A login dialogue pops up:
5. Enter the PIN “20097”.
This will start up SUSI in the service mode.
Click at the enter key to continue.
6. SUSI’s main window now opens, with the “Application” tab displaying a list of supported devices:
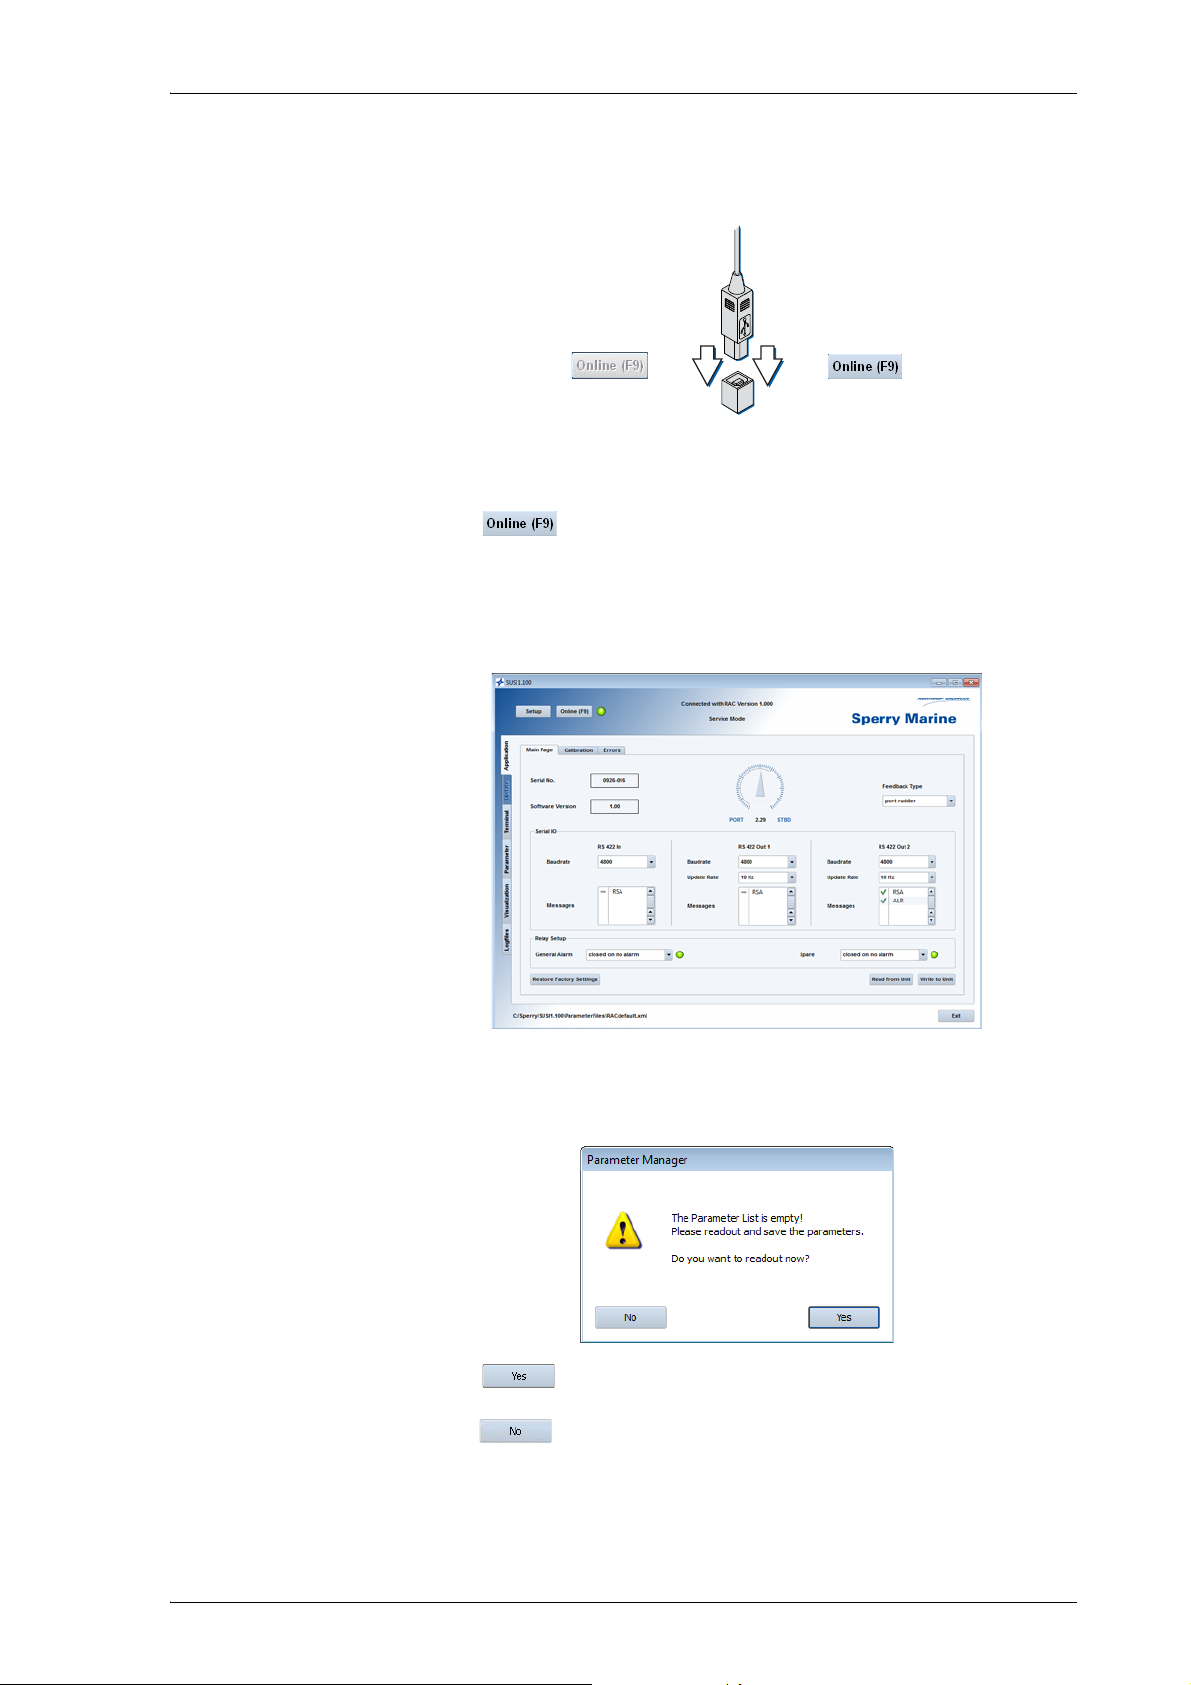
7. The “Online” button at the top left of SUSI’s main window will be
greyed out, as SUSI has not yet detected a device to connect to.
The top status line at the top center of the window will read “Waiting
for Connection...”.
6-2 Initial system configuration
Page 33
RAIS 056357/B
8. Plug in the USB cable at the PC and at the RAC’s service port.
The “Online” button should now become clickable (not greyed-out),
indicating that SUSI has found a device to connect to:
The LED icon next to the button will remain grey, as no connection
has been made yet.
9. Click to connect to the RAC.
The LED icon should now change to green and the status line should
read “Connected with RAC”.
Upon connection, SUSI populates the Application tab with the RAC
application controls and displays the application’s “Main Page”:
10. If the service PC has not previously been used to service a RAC, a
warning message will pop up, indicating that the parameter list for
the device is empty:
Click . to read the current configuration from the RAC and to
set the Main page parameter controls accordingly, or
click . if you intend to set all parameters manually in SUSI
first and write them to the RAC later.
Initial system configuration 6-3
Page 34
056357/B RAIS
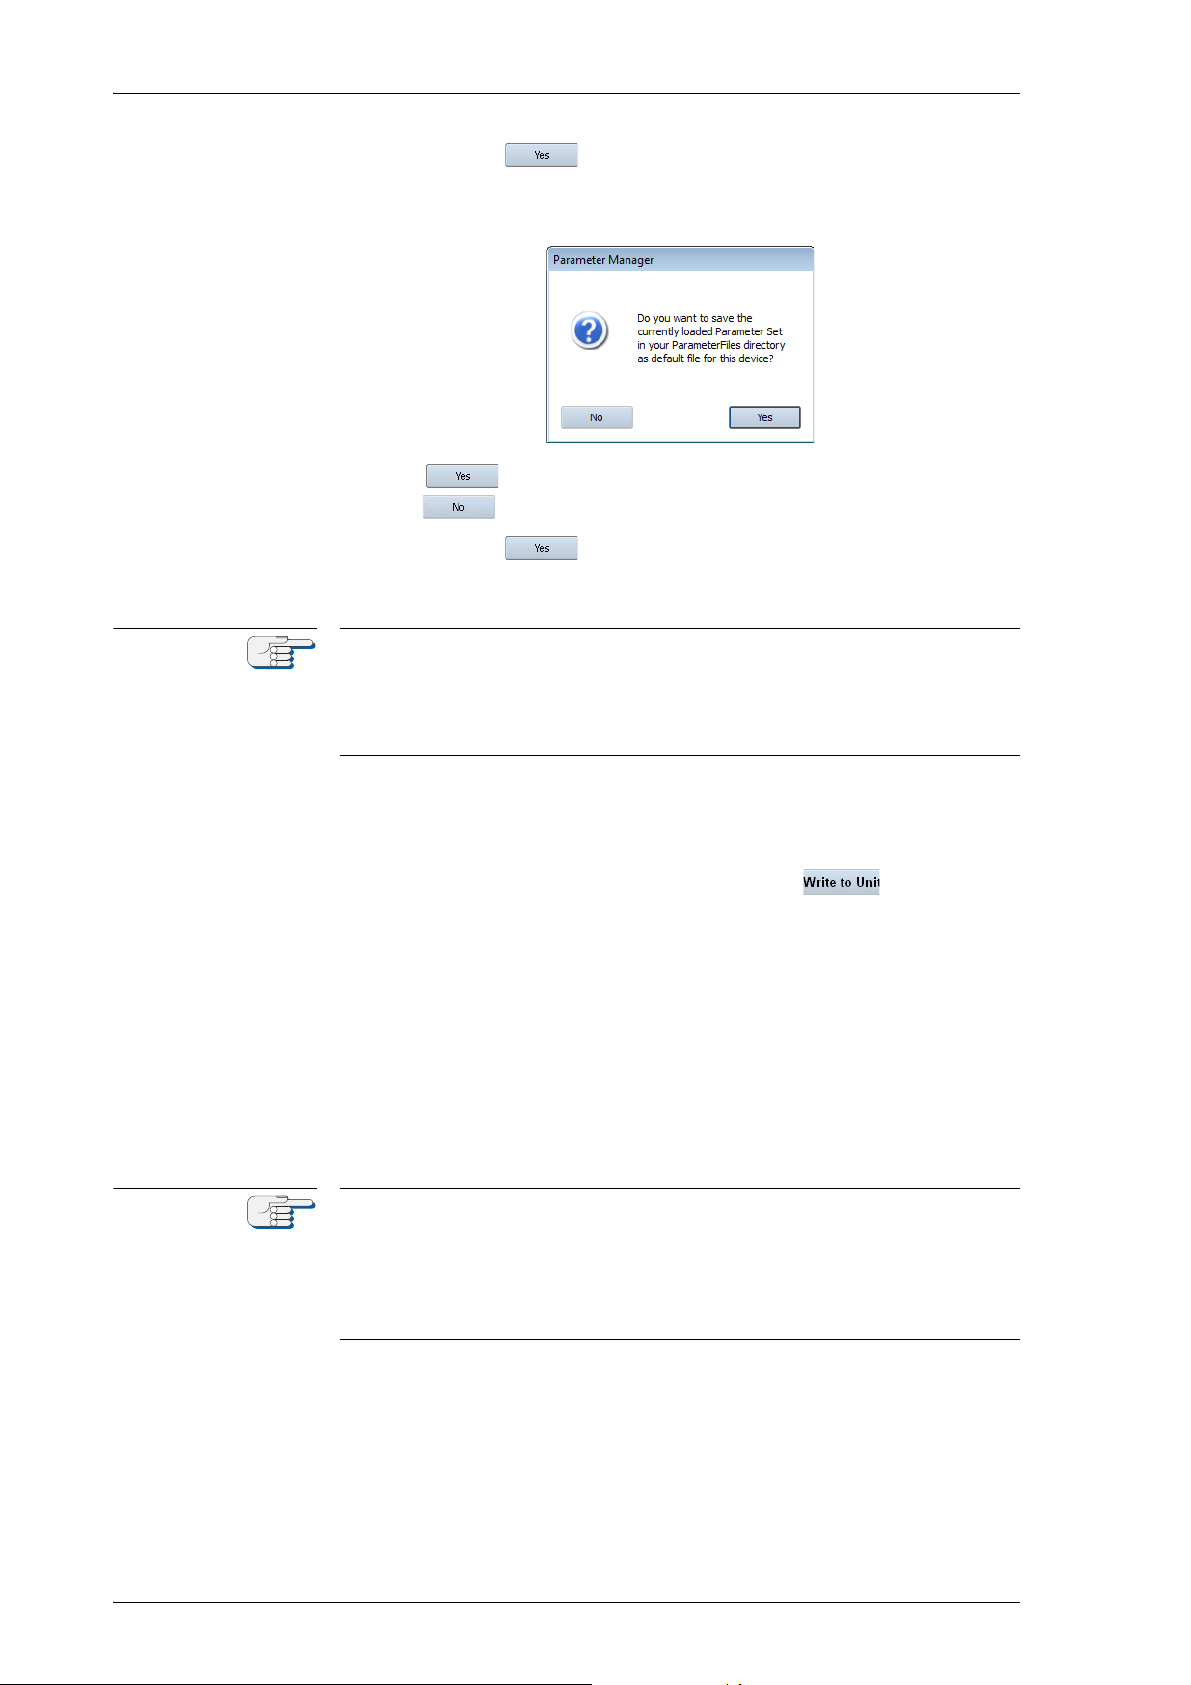
Note
Note
11. If you clicked in the previous step, a dialogue box will pop
up, asking whether the parameters should be saved as default settings for this device:
Click . to save the parameters as default settings or
click to cancel.
12. If you clicked in the previous step, the default settings are
now written to a file named “RACdefault.xml“ in the sub-directory
“Parameter Files” in SUSI’s installation directory.
If a default parameter file for the Rudder Angle Calibrator already exists,
e. g. if the service PC previously been used to service another RAC, the
warning message described above will not appear.
In this case, do not write back settings to the RAC before all system
parameters have been set as required for the installation at hand.
13. Using the Main page controls, set all system parameters as required.
An overview and detailed descriptions of the system parameters are
given below (see “System Parameters” on page 6-6).
14. When all parameters are set as required, click to transfer the
settings to the RAC.
15. Carry out the initial calibration procedure (see “Initial Calibration” on
page 6-16).
If the steering gear is operative and permission is given to actuate
the rudder, start with the input calibration.
If the rudder cannot be actuated now, an input calibration may be
carried out using dummy input signals (see “Input Calibration using
Dummy Values” on page 6-24).
Continue with the output calibration, calibrating at least one of the
analogue outputs. If no RAI is connected to the RAC yet, dummy values may be supplied for the output calibration.
The setting of the system parameters and the input and output calibration may be carried out at different points in time.
However, the Rudder Angle Calibrator’s initial configuration is complete
only if all three of these tasks have been completed successfully and it
has been checked that the required calibration accuracy is attained with
all components of the RAI system being connected and operational.
16. When the in- and output calibration procedures have been fully completed and all components of the RAI system are operational, carry
out a brief function-check.
6-4 Initial system configuration
Page 35
RAIS 056357/B
Note
17. Determine the calibration accuracy attained through the initial calibration. For this purpose, compare the actual angle at the rudder
stock with the angles displayed at the RAIs.
In conformance with the requirements of ISO 20673, the angles
should be recorded every 5° for a ±45° steering gear and every 10°
for a ±70° steering gear.
18. Should the difference between the angles at the rudder stock and the
values shown at the RAIs exceed 1.5% of the full scale angle (performance requirement according to ISO 20673), determine the angles
where the largest errors occur.
Then, set additional input and/or output calibration points for these
angles and determine the calibration accuracy again.
If necessary, repeat this step until the required calibration accuracy
is attained.
19. The RAC configuration as such is now complete and the unit is ready
to be taken into operation.
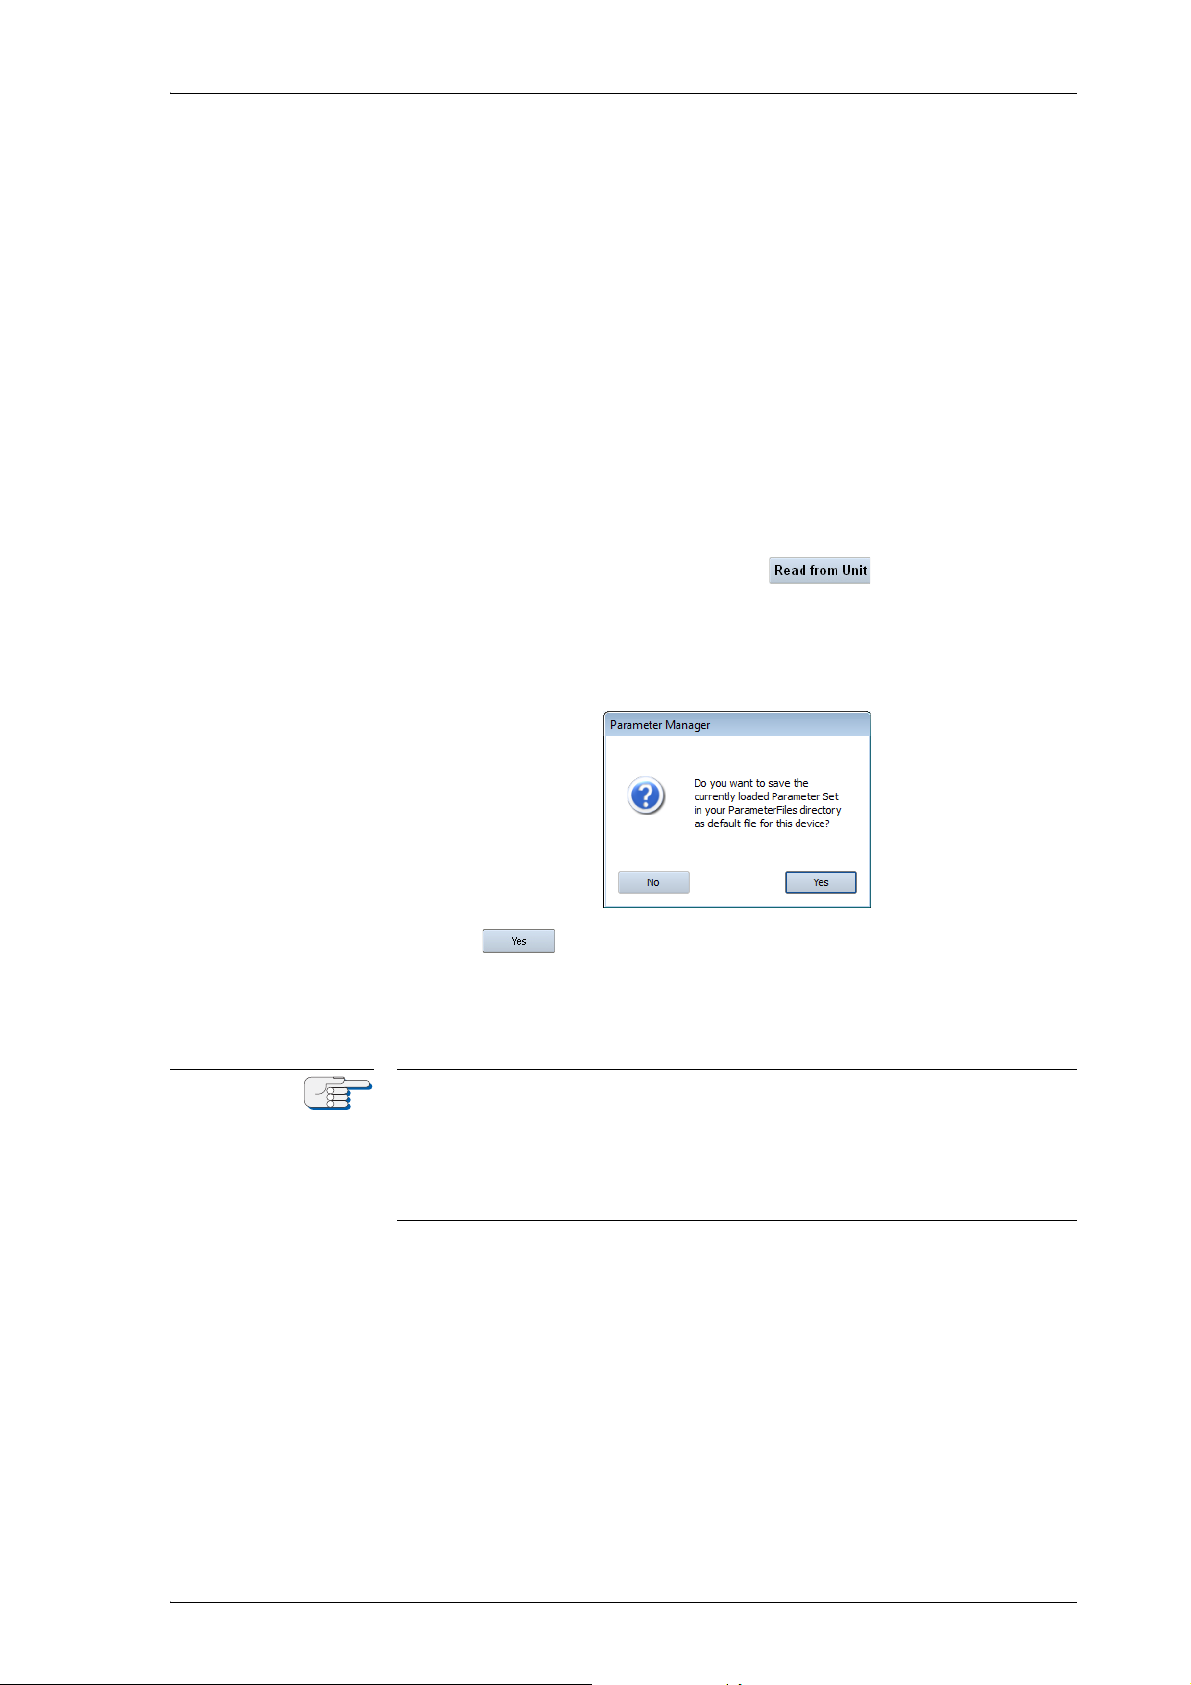
20. To finish off the configuration, click in the SUSI application to read all configuration and calibration settings from the RAC
back into SUSI’s runtime memory.
A dialog box will pop up, asking whether these parameters should
be saved as default settings for this device:
21. Click to save the parameters. The file containing the configuration parameters is named “RACdefault.xml“ and is located in the
sub-directory “Parameter Files” in SUSI’s installation directory.
To be able to retrieve and restore the configuration at a later point in
time, this file should be copied and saved to an appropriate location.
Saving the Rudder Angle Calibrator settings will overwrite a previously
saved settings file in SUSI’s “Parameter Files” sub-directory without further warning.
To be able to retrieve and restore the configuration at a later point in
time, rename the file “RACdefault.xml“ and/or copy it from the “Parameter Files” sub-directory to a different location.
22. Fill out the RAC setup table to retain an easily retrievable written
record of the RAC configuration.
23. Unplug the USB cable from the RAC and the service PC.
24. Power down the RAC and put the cover back on the housing.
25. If the RAC is to be taken into operation now, power up the unit again.
Re-check for proper operation.
Initial system configuration 6-5
Page 36
056357/B RAIS
Feedback Type
port rudder
starboard rudder
single rudder
Serial I/O
RS-422 In
Baudrate
38400
9600
4800
Messages
RSA
RS-422 Out 1
Baudrate
38400
9600
4800
Messages
RSA
RS-422 Out 2
Baudrate
38400
9600
4800
Messages
RSA
ALR
Update Rate
1 Hz
10 Hz
Update Rate
1 Hz
10 Hz
Relay Setup
General Alarm
closed on alarm
closed on no alarm
closed on alarm
closed on no alarm
Spare
2
3
4
1
Read-Only Controls:
RAC Serial No., Software Version, Act. Feedback Angle
System Parameter Controls:
1
2
3
4
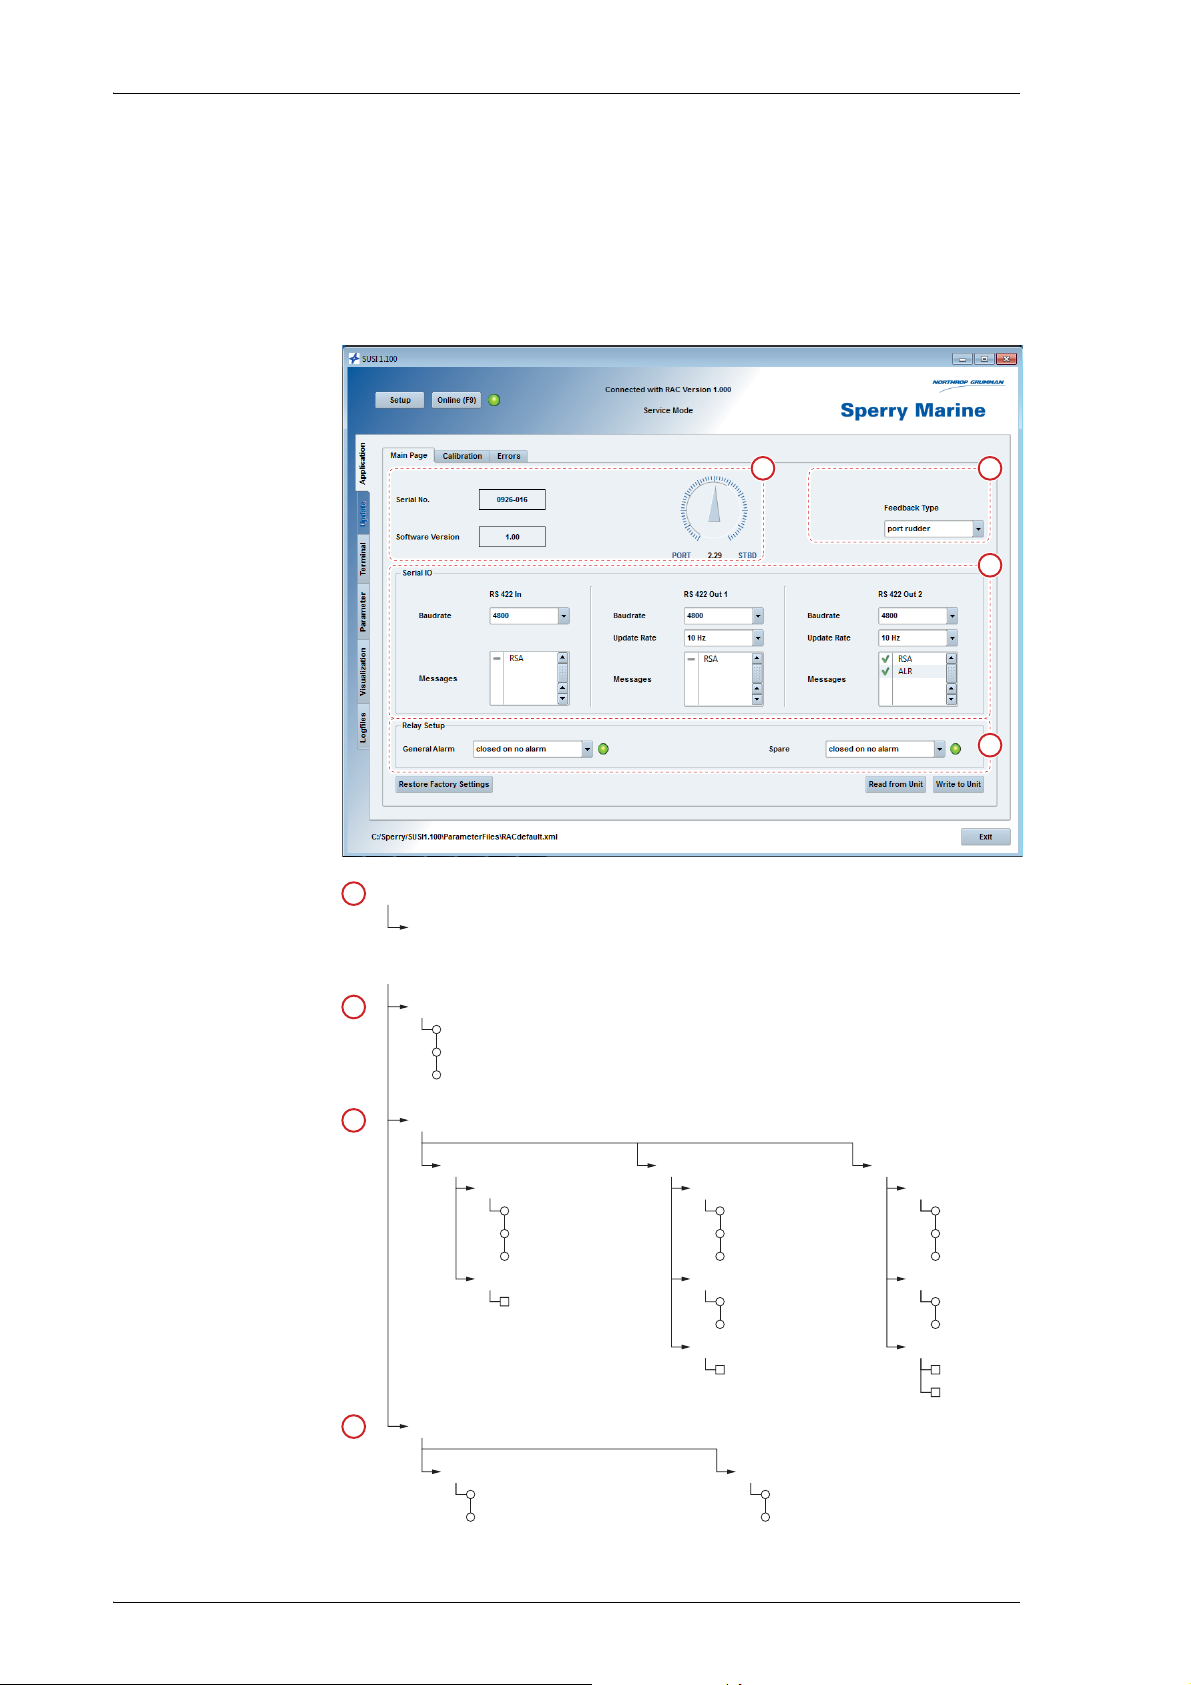
6.2 System Parameters
The Rudder Angle Calibrator application Main page contains a number
of settable interface controls. These are used to configure the RAC’s
basic system parameters as required for the installation at hand.
The settable system parameters fall into three groups, the Feedback
Type setting, the Serial I/O settings and the Relay Setup.
Figure 6-1:
Controls on the RAC
application Main page
6-6 System Parameters
Page 37
RAIS 056357/B
Feedback Type
Selects the type of the input feedback signal.
Setting: single rudder
The input signal is read from the feedback unit of a single
rudder steering gear.
The RAC’s serial data outputs transmit the own rudder angle
as the “starboard (or single) rudder sensor angle” in the $-RSA sentence. The “port rudder sensor angle” will be transmitted as a null field.
starboard rudder
The input signal is read from the starboard feedback unit of
a dual rudder steering gear.
The RAC’s serial data outputs transmit the own rudder angle
as the “starboard (or single) rudder sensor angle” in the $-RSA sentence. If a valid port rudder angle is read from a second Rudder Angle Calibrator at the serial input, it will be
transmitted as the “port rudder sensor angle” in the $--RSA
sentence.
port rudder
The input signal is read from the port feedback unit of a dual
rudder steering gear.
The RAC’s serial data output transmits the own rudder angle
as the “port rudder sensor angle” in the $--RSA sentence. If
a valid starboard rudder angle is read from a second RAC at
the serial input, it will be transmitted as the “starboard (or
single) rudder sensor angle” in the $--RSA sentence.
System Parameters 6-7
Page 38
056357/B RAIS
Serial I/O
These settings configure the RAC’s serial data ports.
RS-422 In
Configures the RS- 422 serial data input.
Baudrate
Selects the receive baudrate.
Settings: 4800 Baud
Data is received at 4800 Baud
(standard according to NMEA / IEC 61162-1).
9600 Baud
Data is received at 9600 Baud
(non-standard).
38400 Baud
Data is received at 38400 Baud
(high-speed, not compliant to IEC 61162-2)
Messages
Selects the NMEA sentences to receive.
Settings RSA
In a dual rudder system, evaluate the $--RSA sentence
received from another RAC.
If a stb. Rudder Angle Calibrator receives a valid port angle
or if a port RAC receives a valid stb. angle, the unit transmits
a $--RSA sentence containing both of these angles.
Select (check) this option in a dual rudder system where the
stb. and port RACs are connected via a serial data crosslink.
De-select (uncheck) this option in all other cases.
6-8 System Parameters
Page 39
RAIS 056357/B
CAUTION
RS-422 Out 1
Configures the RS- 422 serial data output 1 (rudder angle output).
Baudrate
Selects the transmit baudrate.
Settings: 4800 Baud
Data is transmitted at 4800 Baud
(standard according to NMEA / IEC 61162-1).
9600 Baud
Data is transmitted at 9600 Baud
(non-standard).
38400 Baud*
Data is transmitted at 38400 Baud
(high-speed, not compliant to IEC 61162-2).
Risk of misusage
The RS-422 output 1 and RS-422 output 2 of the RAC is not
MED compliant in case 38400 baud are selected as interface setting.
Always make sure that another baud rate setting (4880 or 9600 baud)
must be selected as RS-422 output 1 and RS-422 output, when the RAC is
used on a ship under wheelmark certification
Update Rate
Selects the rate at which output sentences are transmitted.
Settings: 10 Hz
Sentences are transmitted at a rate of 10 Hz.
This option should be selected only if a rate of 1 Hz would
be too slow, e. g. when the serial rudder angle data is used
to feed a live display.
1 Hz
Sentences are transmitted at a rate of 1 Hz.
This rate should suffice in most cases and should be
selected unless a higher rate is absolutely required.
Messages
Selects the NMEA sentences to transmit.
Settings: RSA
Transmit the rudder angle(s) using the $--RSA sentence.
Select (check) this option to activate transmission of the $-RSA sentence at the RS-422 serial output 1.
De-select (uncheck) this option to disable transmission of
the $--RSA sentence at the RS-422 serial output 1. This will
disable the output completely.
System Parameters 6-9
Page 40
056357/B RAIS
CAUTION
CAUTION
RS-422 Out 2
Configures the RS- 422 serial data output 2 (VDR output).
Baudrate
Selects the transmit baudrate.
Settings: 4800 Baud
Data is transmitted at 4800 Baud
(standard according to NMEA / IEC 61162-1).
9600 Baud
Data is transmitted at 9600 Baud
(non-standard).
38400 Baud*
Data is transmitted at 38400 Baud
(high-speed, not compliant to IEC 61162-2)
Risk of misusage
The RS-422 output 1 and RS-422 output 2 of the RAC is not
MED compliant in case 38400 baud are selected as interface setting.
Always make sure that another baud rate setting (4880 or 9600 baud)
must be selected as RS-422 output 1 and RS-422 output, when the RAC is
used on a ship under wheelmark certification
Update Rate
Selects the rate at which output sentences are transmitted.
Settings: 10 Hz
Sentences are transmitted at a rate of 10 Hz.
This option should be selected only if a rate of 1 Hz would
be too slow, e. g. when the serial rudder angle data is used
to feed a live display.
Note that $--ALR sentences are always transmitted at 1 Hz,
regardless of the update rate setting.
1 Hz
Sentences are transmitted at a rate of 1 Hz.
This rate should suffice in most cases and should be
selected unless a higher rate is absolutely required.
Messages
Selects the NMEA sentences to receive.
Risk of misusage
The ALR sentence as serial output of the RAC is not MED complaint and
therefore NOT allowed as system setting for a ship under wheelmark
certification.
Always make sure that the ALR sentence setting is INACTIVATED when
the RAC is used on a ship under wheelmark certification.
6-10 System Parameters
Page 41
RAIS 056357/B
Settings: RSA
Transmit the rudder angle(s) using the $--RSA sentence.
Select (check) this option to activate transmission of the $-RSA sentence at the RS-422 serial output 2.
De-select (uncheck) this option to disable transmission of
the $--RSA sentence at the RS-422 serial output 1.
Settings: ALR
Transmit the RAC’s set alarm state using the
$--ALR sentence.
Select (check) this option to activate transmission of the $-ALR sentence at the RS-422 serial output 2.
De-select (uncheck) this option to disable transmission of
the $--RSA sentence at the RS-422 serial output 2.
When the output is connected to a VDR, it is recommended
to limit the message update rate to 1 Hz and to disable
transmission of data which is already fed to the VDR from
another source.
Disabling both options will disable the output completely.
Relay Setup
Configures the status relay outputs.
General Alarm
Configures the “Power Fail. / Gen. Alarm” relay output
Settings: Closed on no alarm
The relay contact is closed in the “no alarm” state.
On alarm, the contact opens.
Closed on alarm
The relay contact is open in the “no alarm” state.
On alarm, the contact closes.
Spare
Configures the “Spare” relay output
Settings: Closed on no alarm
The relay contact is closed in the “no alarm” state.
On alarm, the contact opens.
Closed on alarm
The relay contact is open in the “no alarm” state.
On alarm, the contact closes.
System Parameters 6-11
Page 42
056357/B RAIS
WAR NING
Note
6.3 In- and Output Calibration
Risk of personal injury
To calibrate the feedback input, the rudder has to be moved over its
entire range. Always make sure that the steering gear is operative and
that the rudder may be actuated safely without any risk of personal
injury or damage to equipment, especially when the vessel is drydocked
and works are carried out by shipyard personnel.
Always inform the shipboard or shipyard personnel in charge of your
intention to actuate the rudder and obtain permission to operate the
steering gear for calibration purposes, before moving the rudder.
The calibration procedures require that tasks are carried out at different
locations on the vessel.
If possible, use voice communication to instruct one or more helpers to
report the actual rudder angle indications as read from the rudder stock
scale and indicated at the RAIs respectively.
To attain the calibration accuracy required to comply with ISO 20673 for
all RAIs connected, the RAC applies calibration to the input signal as
well as to all analogue outputs separately.
Before the system may be taken into operation, the feedback input and
all used outputs are to be calibrated. The RAC application’s calibration
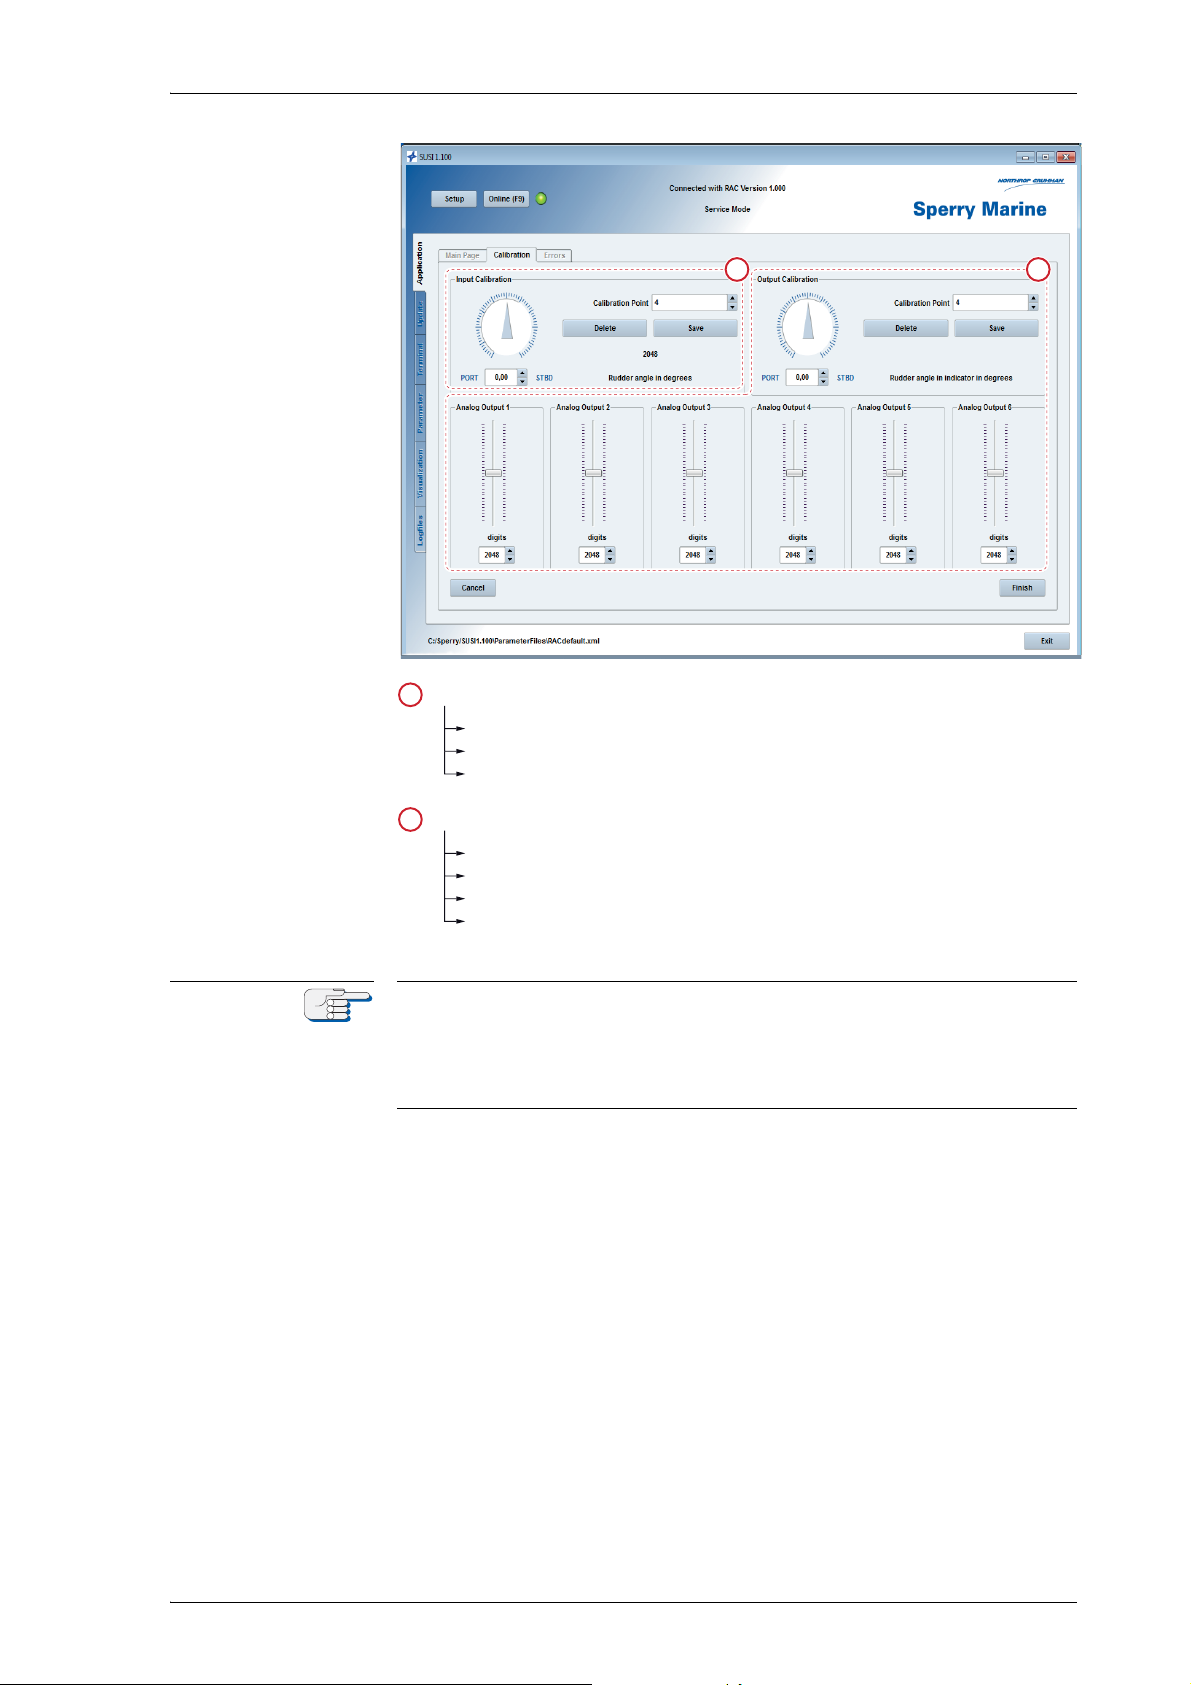
page provides the required controls for these tasks:
6-12 In- and Output Calibration
Page 43
RAIS 056357/B
Note
Figure 6-2:
Controls on the RAC
calibration page
1
Input Calibration Controls:
Rudder Angle dial and spin box
Calibration Point spin box
Delete and Save buttons
2
Output Calibration Controls:
1
2
Rudder Angle Indicator dial and spin box
Calibration Point spin box
Delete and Save buttons
Output Digit sliders and spin boxes
Accessing the calibration page puts the Rudder Angle Calibrator into a
special calibration mode. In this mode, the analogue output voltages do
not correspond to the actual rudder angle but are determined directly by
the settings of the output calibration controls. Serial output of the rudder
angle is disabled in the calibration mode.
In- and Output Calibration 6-13
Page 44
056357/B RAIS
Input Calibration Table
To compensate for possible misalignment of the feedback unit and nonlinearity of the feedback potentiometer, the RAC permanently applies
correction to the input value, according to a stored calibration table.
The input calibration table contains a number of calibration points, each
of which maps a feedback input value to the corresponding true rudder
angle, as read from the rudder stock scale. Values in-between the set
calibration points are linearly interpolated.
As a minimum, three calibration points must be set. Normally, an initial
input calibration is carried out where calibration points are set at every
5° for a ±45° steering gear and every 10° for a ±70° steering gear.
This makes sure that the optimum calibration is achieved at the rudder
angles where the calibration accuracy is to be checked later, according
to ISO 20673.
Additional calibration points may be added later, up to a total of 73.
Output Calibration Table
To compensate for the existing non-linearities and zero-point offsets of
the connected RAIs, the RAC permanently applies correction to the analogue output signals, according to a stored output calibration table.
The output calibration table contains a number of calibration points,
each of which maps an actual rudder angle value to a set of six corresponding output voltage values. Values in-between the set calibration
points are linearly interpolated.
As a minimum, three calibration points must be set. Normally, an initial
output calibration is carried out, to set calibration points for the hardover port, the midships and the hardover starboard rudder indications.
Additional calibration points may be added later, up to a total of 73.
6-14 In- and Output Calibration
Page 45
RAIS 056357/B
General Remarks on Calibration
With regard to the RAC in- and output calibration using SUSI, observe
the following points:
• Port rudder angles are displayed as negative numbers in SUSI.
Accordingly, port angles must also be entered as negative numbers,
prefixed with a minus sign. Starboard angles carry no sign.
Thus, “-45.0°” denotes an angle of 45 degrees to port, “45.0°”
denotes an angle of 45 degrees to starboard.
• Calibration settings are written back to the RAC when the calibration
page is quit by clicking “Finish”. However, SUSI refuses to write
back the calibration settings to the RAC before the minimum number
of three input and three output calibration points has been set.
Clicking “Cancel” quits the calibration page and discards all
changes, leaving the RAC settings untouched.
• Consequently, when deleting existing calibration points, at least
three input and three output points must remain set.
Otherwise, an error message will be displayed when attempting to
quit the page by clicking “Finish” and it will not be possible to save
any of the changes made since the page was entered.
• Once an in- or output calibration point has been set, the rudder
angle value stored for this point cannot be altered directly.
Instead, the settings of an existing calibration point will be overwritten if a new point is added for exactly the same rudder angle value.
The analogue in- or output values associated with a given calibration
point, however, may be freely edited after the point has been set.
• When adding an output calibration point, all analogue outputs are
set to provide a nominal 0 V signal at the respective rudder angle.
Therefore, the indicated rudder angle must be read at all connected
RAIs and the output values adjusted whenever an output calibration
point is added.
• The largest port and starboard rudder angles for which input calibration points exist are taken as range limits for the RAC’s internal rudder scale. The angles transmitted at the analogue and the serial data
outputs cannot exceed these limits.
Therefore, input calibration points must be set at the hardover starboard and hardover port positions. It is recommended to use NFU
control to position the rudder to the absolute mechanical limit when
setting the hardover calibration points.
• The input polarity may be reversed by applying positive input voltages for port angles and negative voltages for starboard angles.
Likewise, an output’s polarity may be reversed by generating positive output voltages for port angles and negative voltages for starboard angles.
However, the in- and output voltages must ascend or descend steadily along the rudder angle range. In particular, the input signal curve
may not exhibit peaks or troughs, as this would imply that the same
input voltage could occur at different rudder angles.
In- and Output Calibration 6-15
Page 46
056357/B RAIS
WAR NING
Note
Initial Calibration
As delivered from the factory, the RAC is not yet able to take up normal
operation. At least three input and three output calibration points must
be set to make the outputs become functional.
Sperry Marine recommends to carry out an initial calibration directly
after the basic configuration parameters have been set.
During this initial calibration, input calibration points are to be set at the
hardover and midships rudder positions. Output calibration points are
then to be set for the hardover and rudder midships indications. After
this initial calibration, it is always possible to set further calibration
points or to edit existing ones.
Providing that the feedback unit has been carefully adjusted mechanically and that the RAIs do not exhibit severe non-linearities, the initial
calibration should already result in sufficient calibration accuracy in
many cases.
During a performance check according to ISO_20673, the angles shown
by the RAIs will be recorded at every 5° for a ±45° steering gear and
every 10° for a ±70° steering gear. To meet the required accuracy, the difference between the angles of the transmitter shaft (rudder stock) and
the corresponding value shown at the RAIs is to be less than 1.5% of the
indicators’ full scale value.
Should this accuracy not be attained after the initial calibration, additional calibration points need to be set.
Errors affecting all outputs, including the serial data outputs, are corrected by setting additional input calibration points. Errors affecting
individual analogue outputs only are corrected by setting additional output calibration points
Such additional points may be set systematically at every 5° for a ±45°
steering gear and every 10° for a ±70° steering gear. This ensures optimum calibration for the angles at which the accuracy is tested according
to ISO_20673.
Alternatively, it is also possible to determine the rudder angles where
the largest errors occur and to set calibration points at exactly these
angles. By repeating this procedure until the required accuracy is met,
good results are achieved with as few calibration points as possible.
Risk of personal injury
To calibrate the feedback input, the rudder has to be moved over its
entire range. Always make sure that the steering gear is operative and
that the rudder may be actuated safely without any risk of personal
injury or damage to equipment, especially when the vessel is drydocked
and works are carried out by shipyard personnel.
Always inform the shipboard or shipyard personnel in charge of your
intention to actuate the rudder and obtain permission to operate the
steering gear for calibration purposes, before moving the rudder.
The calibration procedures require that tasks are carried out at different
locations on the vessel.
If possible, use voice communication to instruct one or more helpers to
report the actual rudder angle indications as read from the rudder stock
scale and indicated at the RAIs respectively.
6-16 In- and Output Calibration
Page 47
RAIS 056357/B
To carry out the initial calibration:
1. If not already connected, connect to the RAC with SUSI now, as
described in “Configuring the RAC with SUSI”, steps 1 through 12,
starting on page 6-2.
2. Click on the “Calibration” tab of the Rudder Angle Calibrator application to enter the calibration page.
3. As the first part of the initial calibration, the feedback input is to be
calibrated now.
In case the steering gear cannot be operated at this point in time, use
the potentiometer supply and center tap potentials as dummy input
signals (see “Input Calibration using Dummy Values” on page 6-24).
4. Put the rudder to the hardover port position.
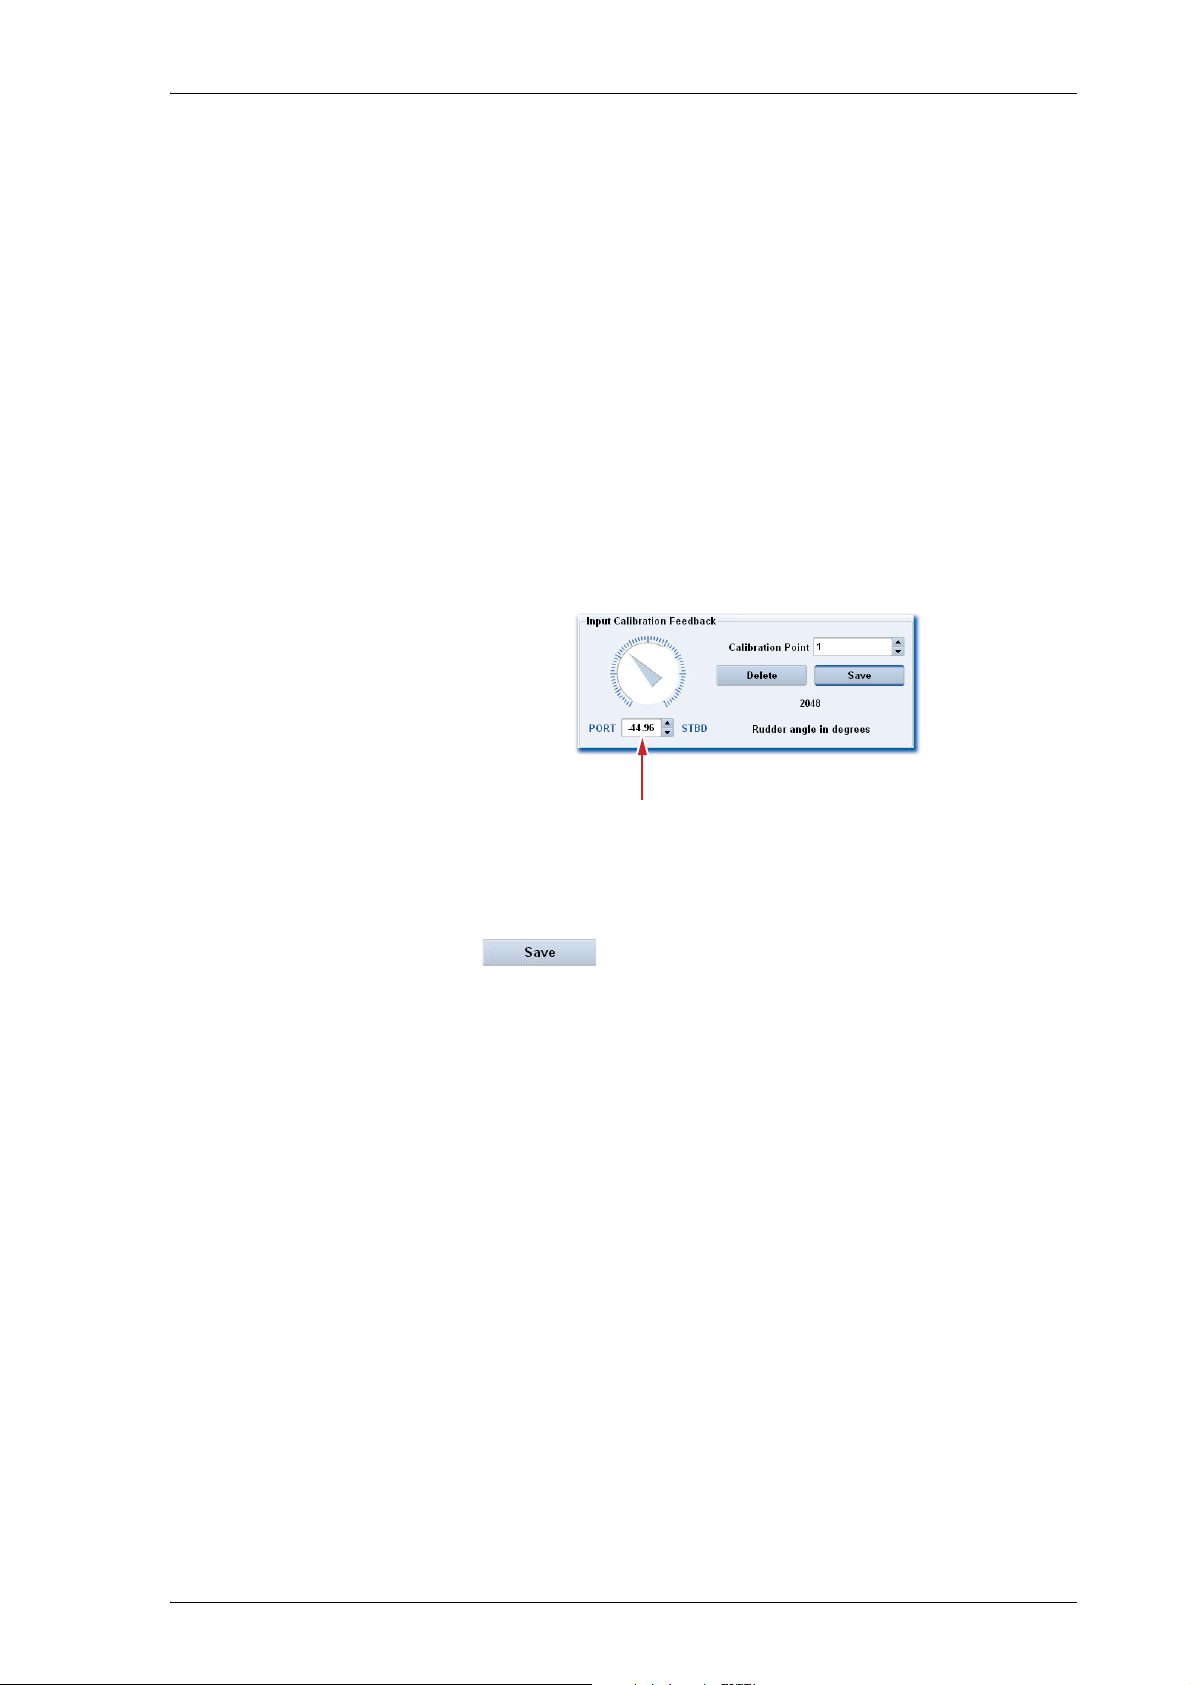
5. Read the exact rudder angle from the rudder stock scale and enter it
in the input calibration rudder angle control.
You may edit the displayed angle directly or use the dial and spin
controls to set it to the required value:
enter exact angle read
from rudder stock scale
Port angles must be entered as negative numbers, i. e. prefixed with
a minus sign.
6. Click to set a new calibration point. The rudder angle
and the corresponding internal A/D conversion value are now saved
to runtime memory.
The calibration point index is incremented automatically. Upon saving a calibration point, all points are re-indexed. The point for the
largest port angle is assigned index “1”, while the point for the largest starboard angle is assigned the index matching the total number
of existing points.
7. Put the rudder to the midships position.
In- and Output Calibration 6-17
Page 48
056357/B RAIS
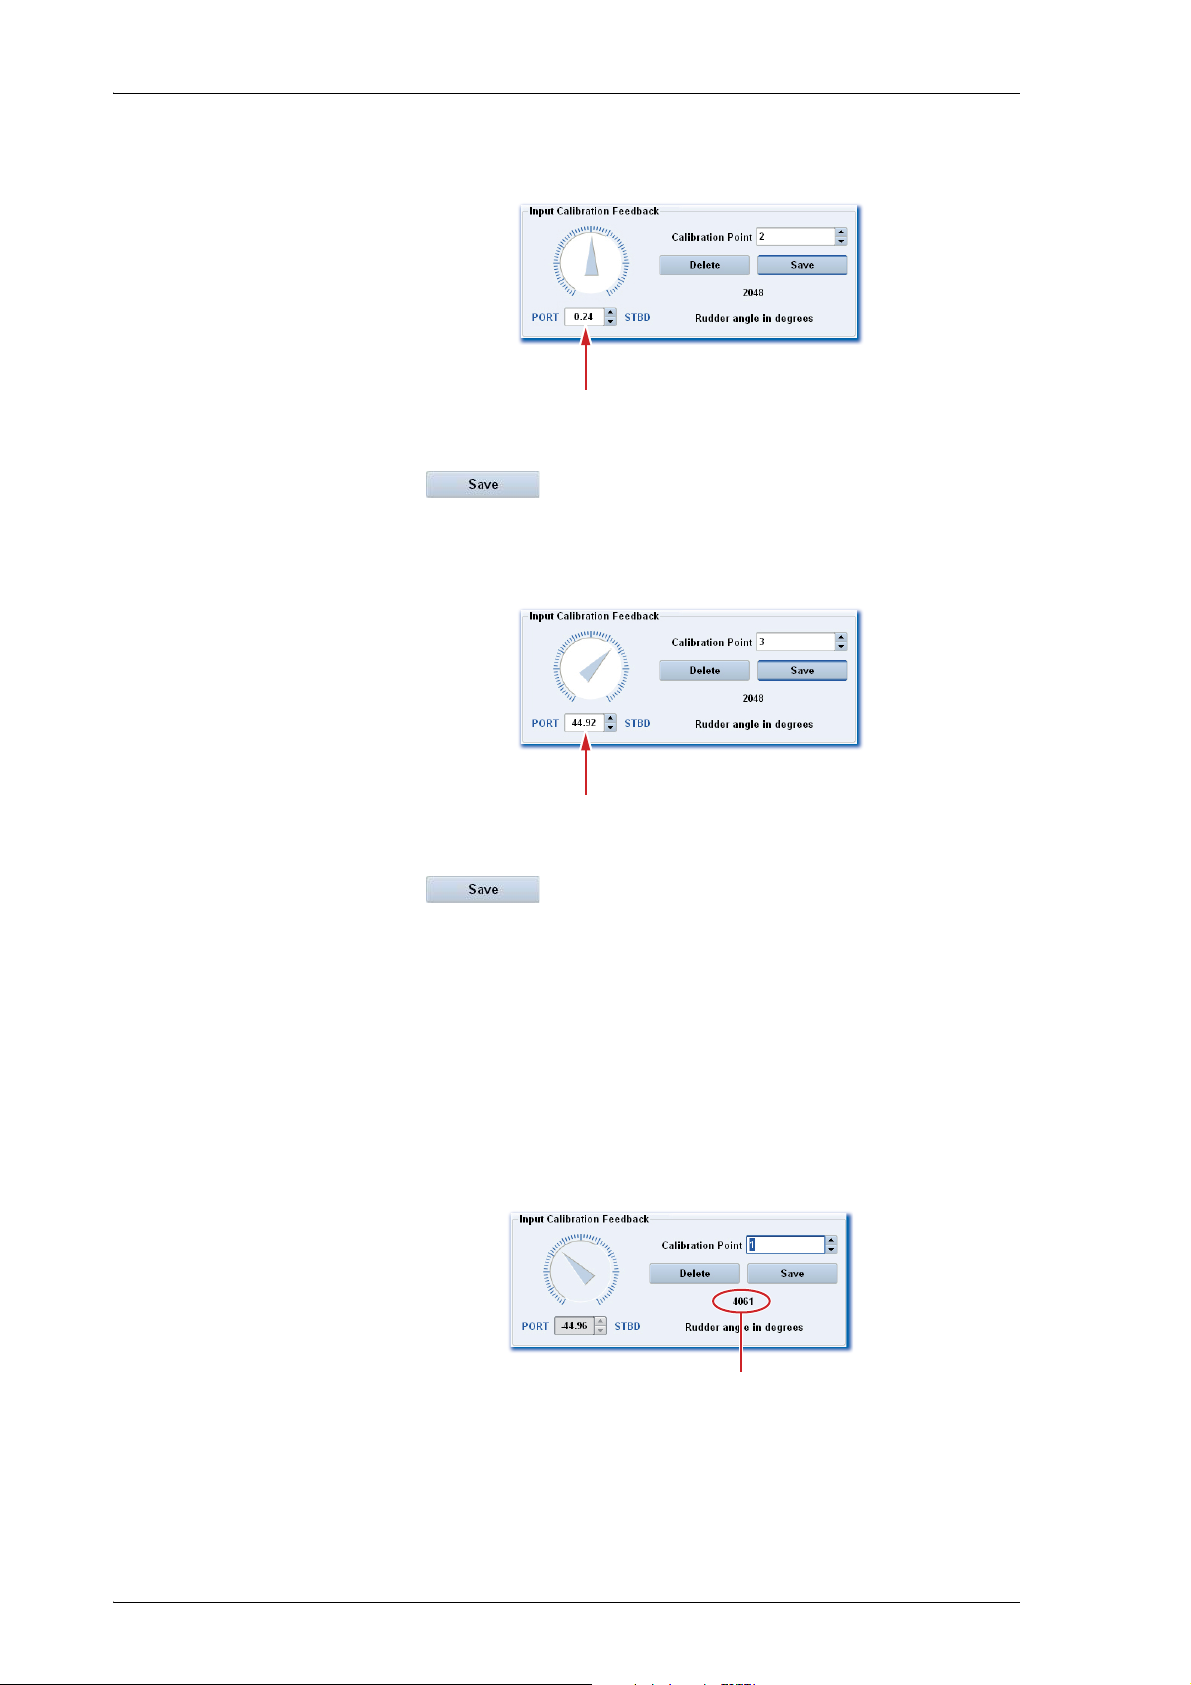
8. Read the exact rudder angle from the rudder stock scale and enter it
in the input calibration rudder angle control:
enter exact angle read
from rudder stock scale
9. Click to set a new calibration point.
10. Put the rudder to the hardover starboard position.
11. Read the exact rudder angle from the rudder stock scale and enter it
in the input calibration rudder angle control:
enter exact angle read
from rudder stock scale
12. Click to set a new calibration point.
13. Check that all input calibration points have been stored correctly:
The calibration point index should now read “4”.
Scroll down the list of calibration points with the spin control and
verify that:
– For points 1 to 3, the rudder angles displayed are those you
entered for the hardover and midships positions. The input controls will be greyed-out for the saved points.
– For each point, the number shown below the “Delete” and
“Save” button lies between 0 and 4095 and is largest for the hardover port and smallest for the hardover starboard value:
feedback signal
A/D conversion value
This number represents the 12-bit A/D conversion value of the
input voltage, at the moment when the respective calibration
point was saved.
6-18 In- and Output Calibration
Page 49
RAIS 056357/B
Note
enter full scale port angle
of connected RAIs
45 45
30
30
1515
0
RAI
adjust output for exact
full-scale port indication
14. At least three output calibration points must be set now before the
calibration page can be quit and the calibration settings are written
to the RAC.
If no RAIs are connected to the RAC at this point in time, zero output values may be entered as a temporary measure, to be able to finish the initial calibration and transfer the calibration settings to the RAC.
The RAC may not be taken into regular operation before all used outputs
have been calibrated with the respective RAIs being installed at their
proper locations.
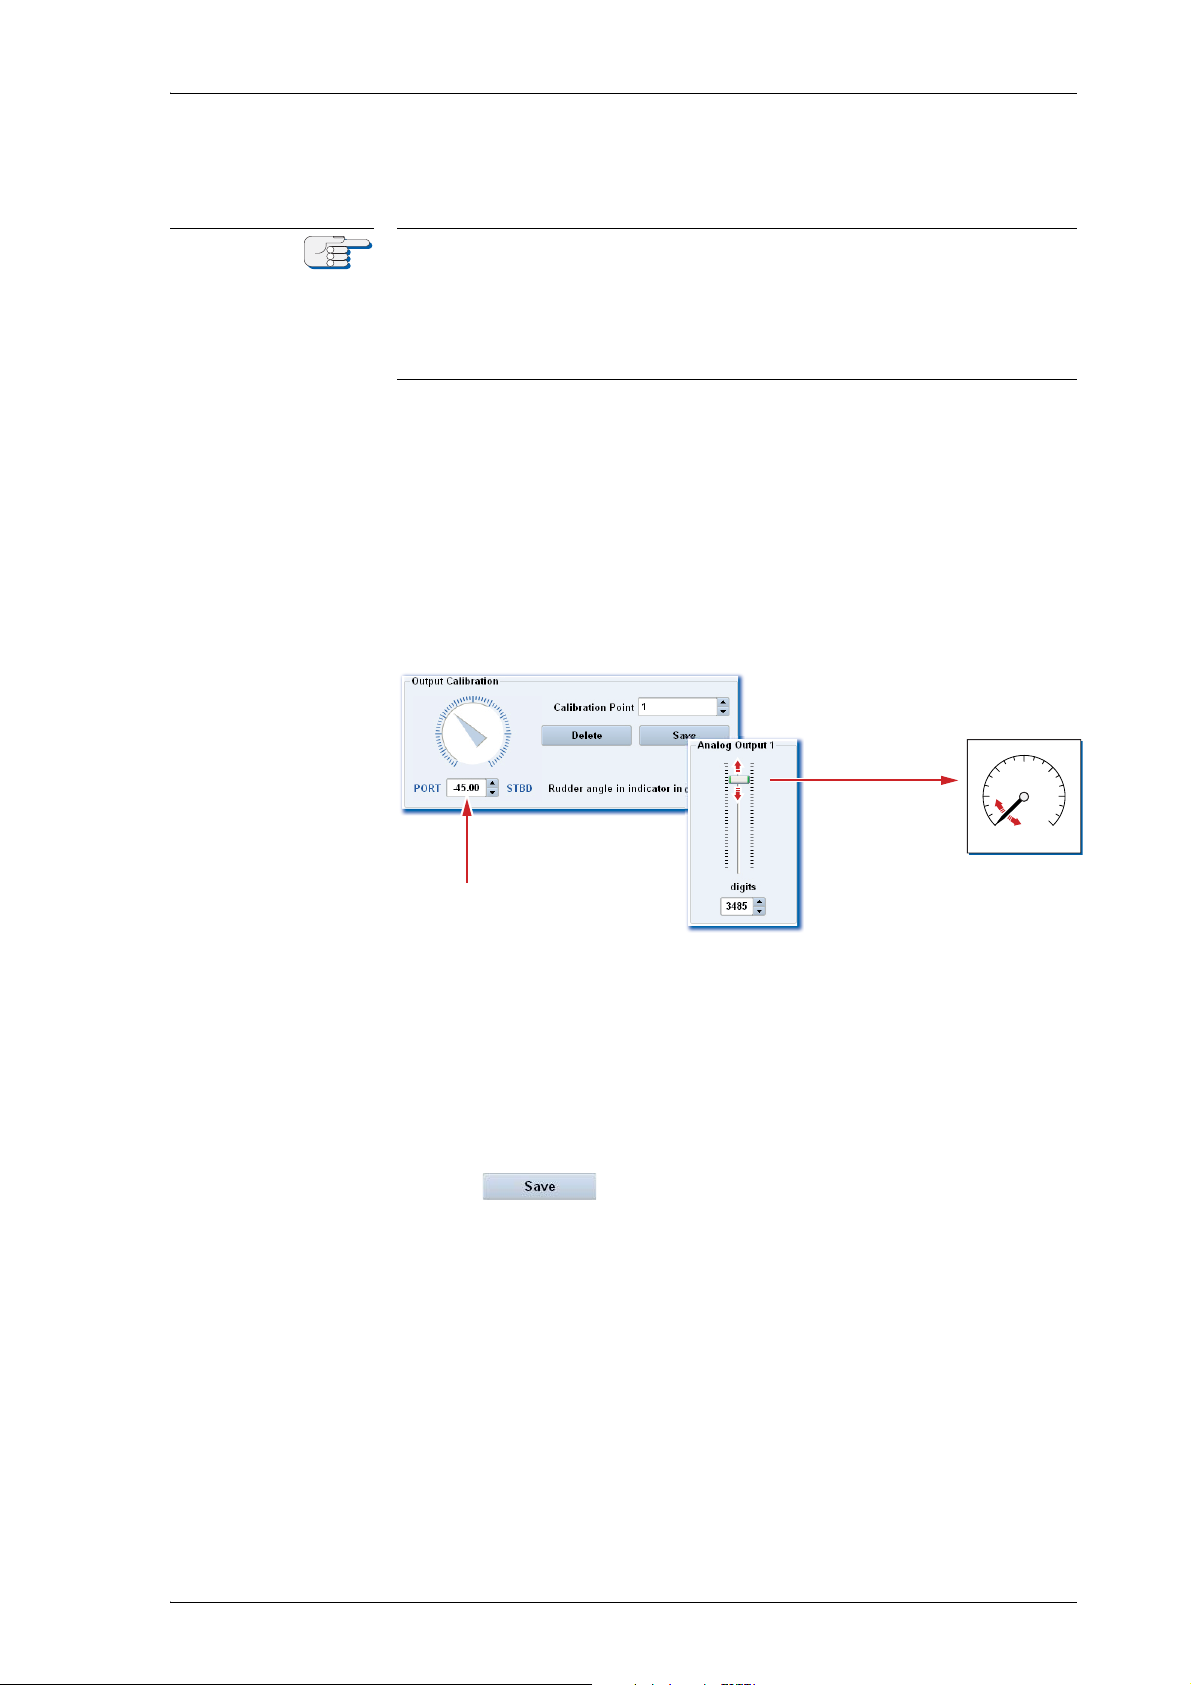
15. Enter the RAI’s full scale port angle in the output calibration rudder
angle control. In most cases, this will be the nominal hardover port
angle, e. g. -45 or -70 degrees.
You may edit the displayed angle directly or use the dial and spin
controls to set it to the required value.
Port angles must be entered as negative numbers, i. e. prefixed with
a minus sign.
16. At the RAIs to calibrate, read the actual rudder angle indication.
Adjust the output sliders in SUSI to bring the RAI’s indication to the
exact full scale port value:
The numbers shown in the analogue output spin boxes are the 12-bit
digital values fed to the D/A converters, to be converted into the analogue output voltages.
Hereby, the number 0 represents the maximum possible positive
output voltage (+15 V nominal) and 4095 represents the maximum
possible negative output voltage (-15 V nominal).
In case no RAIs are connected to the RAC at this point in time, leave
all output settings at the default value of 2048.
17. Click to set a new calibration point. The rudder angle
and the corresponding set of output values are now saved to runtime memory.
The calibration point index is incremented automatically. Upon saving a calibration point, all points are re-indexed. The point for the
largest port angle is assigned index “1”, while the point for the largest starboard angle is assigned the index matching the total number
of existing points.
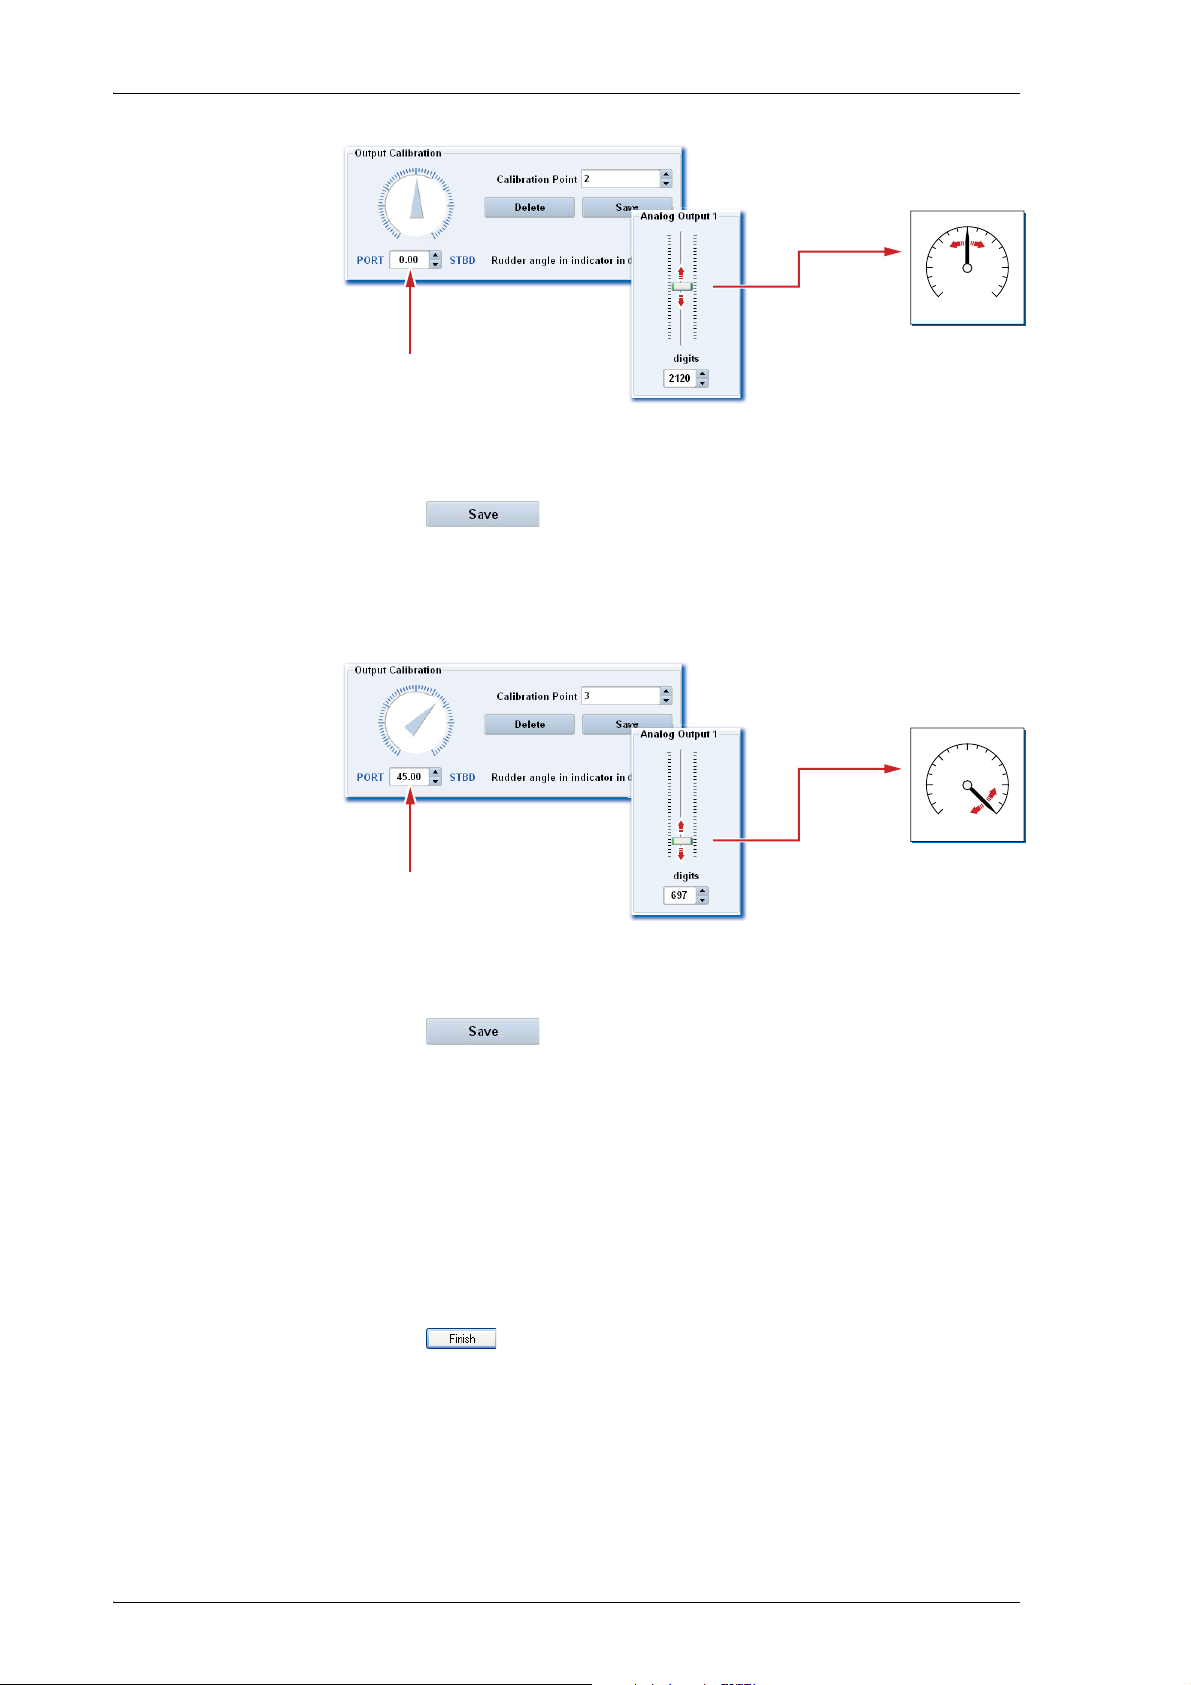
18. Enter 0.0 in the output calibration rudder angle control.
19. At the RAIs to calibrate, read the actual rudder angle indication.
Adjust the output sliders in SUSI to bring each RAI’s indication to
rudder midships exactly:
In- and Output Calibration 6-19
Page 50
056357/B RAIS
enter zero
(rudder midships)
45 45
30
30
1515
0
RAI
adjust output for exact
rudder midships indication
45 45
30
30
1515
0
RAI
adjust output for exact
full-scale stb. indication
enter full scale stb. angle
of connected RAIs
In case no RAIs are connected to the RAC at this point in time, leave
all output settings at the default value of 2048.
20. Click to set a new calibration point.
21. Enter the RAI’s full scale starboard angle in the output calibration
rudder angle control.
22. Adjust the output sliders in SUSI to bring the RAI’s indication to the
exact full scale starboard value:
In case no RAIs are connected to the RAC at this point in time, leave
all output settings at the default value of 2048.
23. Click to set a new calibration point.
24. Check that all output calibration points have been stored correctly:
The calibration point index should now read “4”.
Scroll down the list of calibration points with the spin control and
verify that:
– For points 1 to 3, the rudder angles displayed are those you
entered for the full scale and midships indications. The input
controls will be greyed-out for the saved points.
– For each point, the calibrated RAIs indicate the respective rudder
angle exactly.
25. Click to quit the calibration page and write the calibration
settings to the RAC.
If the above steps have been carried out with all components of the
RAI system being operational, the initial calibration is now complete.
6-20 In- and Output Calibration
Page 51
RAIS 056357/B
Note
In case dummy signals or zero values have been supplied during the inor output calibration, the RAC may not be taken into operation yet.
The configuration of the unit is not complete before the input has been
calibrated using the actual input signal from the feedback potentiometer
and the outputs have been calibrated for the individual RAIs installed.
26. Carry out a first performance check now, to determine whether additional input and/or output calibration points need to be set.
In particular, check the accuracy of the input calibration by comparing the angle read at the rudder stock scale with the angle indicated
on the dial on the RAC application main page in SUSI.
27. If required, set additional input calibration points, applying one of
the following strategies:
– Either, set points at every 5° for a ±45° steering gear and every
10° for a ±70° steering gear.
This ensures optimum calibration for the angles at which the
accuracy is tested according to ISO_20673.
– Or, determine the rudder angles where the largest errors occur
and set calibration points at exactly these angles. Repeat this
procedure until the required accuracy is met.
This ensures good calibration with as few calibration points as
possible.
28. If required, set additional output calibration points to correct the
errors in indication of the RAIs.
While it is possible to set points systematically every 5° or 10°, this
requires to adjust the output for every RAI at every point set.
It will mostly suffice to set calibration points selectively at those indications where individual RAIs exhibit the largest error.
In- and Output Calibration 6-21
Page 52
056357/B RAIS
Note
Adding, Editing and Deleting Calibration Points
After the initial calibration procedures, a performance check of the RAI
system may reveal that the required calibration accuracy is not yet
attained over the entire rudder angle range.
This may happen especially if the feedback lever linkage is poorly
aligned or the feedback unit’s shaft runs not exactly parallel to the rudder stock. It will then be required to set additional input calibration
points or to alter the existing ones.
Once a calibration point has been set, the rudder angle stored for this
point cannot be edited.
Instead, an existing calibration point can be overwritten by adding a new
point at exactly the same rudder angle. However, it is recommended to
always delete an existing point first, before adding a new point at the
same or nearly the same rudder angle.
To add input calibration points:
1. If not already connected, connect to the RAC with SUSI and enter the
RAC application’s calibration page.
2. Put the rudder to the required angle.
3. Read the exact rudder angle from the rudder stock scale and enter it
in the input calibration rudder angle control.
4. Click to add the new calibration point.
5. Repeat steps 2 to 4 above to set further additional calibration points,
if necessary. In total, up to 73 points may be entered.
6. Click to write back the calibration settings to the RAC and
quit the calibration page.
To add output calibration points:
1. If not already connected, connect to the RAC with SUSI and enter the
RAC application’s calibration page.
2. Enter the desired true rudder angle in the output calibration rudder
angle control.
3. At each RAI, read the actual rudder angle indication and adjust the
corresponding output slider in SUSI to bring the RAI’s indication to
the exact value entered in the output rudder angle control.
4. Click to add the new calibration point.
5. Repeat steps 2 to 4 above to set further additional calibration points,
if required. In total, up to 73 points may be entered.
6. Click to write back the calibration settings to the RAC and
quit the calibration page.
6-22 In- and Output Calibration
Page 53
RAIS 056357/B
Note
To edit in- or output calibration points:
1. If not already connected, connect to the RAC with SUSI and enter the
RAC application’s calibration page.
2. With the spin control, scroll down the list of existing calibration
points to the point you wish to edit.
3. In case of an input calibration point:
– If the rudder can be positioned exactly to the angle where the
point has been set, position the rudder to this angle.
Click to save the edited point.
– If the rudder cannot be positioned exactly to the angle where the
point has been set, delete the existing point.
Position the rudder to an angle close to the previous one, then
read the exact rudder angle from the rudder stock scale and enter
it in the input calibration rudder angle control.
Click to save the newly set point.
In case of an output calibration point:
For all of the outputs you wish to edit, adjust the output slider to
bring the respective RAI’s indication to the exact value where the
calibration point has been set.
Click to save the edited point.
4. Repeat steps 2 to 3 above to edit further calibration points, if
required.
5. Click to write back the calibration settings to the RAC and
quit the calibration page.
To delete in- or output calibration points:
1. If not already connected, connect to the RAC with SUSI and enter the
RAC application’s calibration page.
2. With the spin control, scroll down the list of existing calibration
points to the point you wish to delete.
3. Click to delete the point.
4. Repeat steps 2 to 3 above to delete further calibration points, if
required.
5. Click to write back the calibration settings to the RAC and
quit the calibration page.
Make sure not to delete the calibration points for the hardover and midships rudder angles, unless you intend to directly add new points in their
place. At least three points must remain set, otherwise it will not be possible to leave the calibration page by clicking “Finish”.
In- and Output Calibration 6-23
Page 54
056357/B RAIS
Input Calibration using Dummy Values
In some installations, it may be required to carry out the output calibration before the input calibration. E. g., if the RAI system is installed and
wired up, but the rudder cannot be actuated because the steering gear is
not operational. As a temporary measure in such cases, the input may
be calibrated using the feedback potentiometer supply and center tap
potentials as input signals, instead of the actual feedback signal.
To calibrate the input using dummy values:
1. Disconnect the feedback unit from the RAC, TB 1.3 through 1.6
(refer to circuit diagram 5014-0115-01).
2. Proceed as if carrying out the initial input calibration (see “Initial
Calibration” on page 6-16).
However, instead of putting the rudder to the hardover and midships
positions,
– shorten TB 1.4 to 1.5 to connect the negative feedback supply
potential to the input. Then, enter the nominal hardover port
angle (e. g. -45 or -70 degrees) in the rudder angle control and
click to set the hardover port calibration point;
– shorten TB 1.4 to 1.6 to connect the feedback center tap potential
to the input. Then, enter a value of 0.0 degrees in the rudder
angle control and click to set the midships calibration point;
– shorten TB 1.4 to 1.3 to connect the positive feedback supply
potential to the input. Then, enter the nominal hardover starboard angle (e. g. 45 or 70 degrees) in the rudder angle control
and click to set the hardover starboard calibration
point.
3. Re-connect the feedback unit to the RAC, TB 1.3 through 1.6.
6-24 In- and Output Calibration
Page 55
RAIS 056357/B
DANGER
CAUTION
Chapter 7: Troubleshooting
Life danger through electrical shock
Certain alarm devices may operate with hazardous voltages, switched
by the alarm relay output contacts.
NEVER connect live wires to the unit’s terminals, when wiring up the
Rudder Angle Calibrator.
ALWAYS make sure that any external device or power supply to be connected to the alarm relay outputs is de-energized and safeguarded
against accidental switching-on.
Risk of damage of electrostatic-discharge-sensitive components
The
Rudder Angle Calibrator contains electrostatic sensitive components.
Electrostatic discharge may permanently damage components.
When configuring the
electrostatic discharge. Avoid touching any of the electronic circuitry.
Rudder Angle Calibrator, take precautions to prevent
7.1 General Troubleshooting Instructions
The RAC is a complex electronic device. In case of malfunction, it would
neither be practical nor economical to carry out troubleshooting and
servicing in the field down to the level of individual circuit components.
Defective units must be sent back to Sperry Marine for repair.
Field service personnel should limit troubleshooting to the basic checks
given below.
• Visual inspection of mechanical components, the PCB and wiring.
• Continuity checks of wiring connections.
• Checks for short circuit or overload conditions or reversed polarity of
the external supply powers.
• Checks of the on-board supply voltages and I/O signals and data.
The presence of voltages, signals and data is indicated by diagnostic
LEDs on the PCB.
Exact voltage levels must be checked with a voltmeter.
The data content on serial I/O lines must be checked with the aid of
suitable analyzing tools, such as PC-based protocol interpreters or
terminal programs.
• Software-aided troubleshooting using Sperry Marine’s SUSI application, if instructed accordingly by Sperry Marine.
General Troubleshooting Instructions 7-1
Page 56
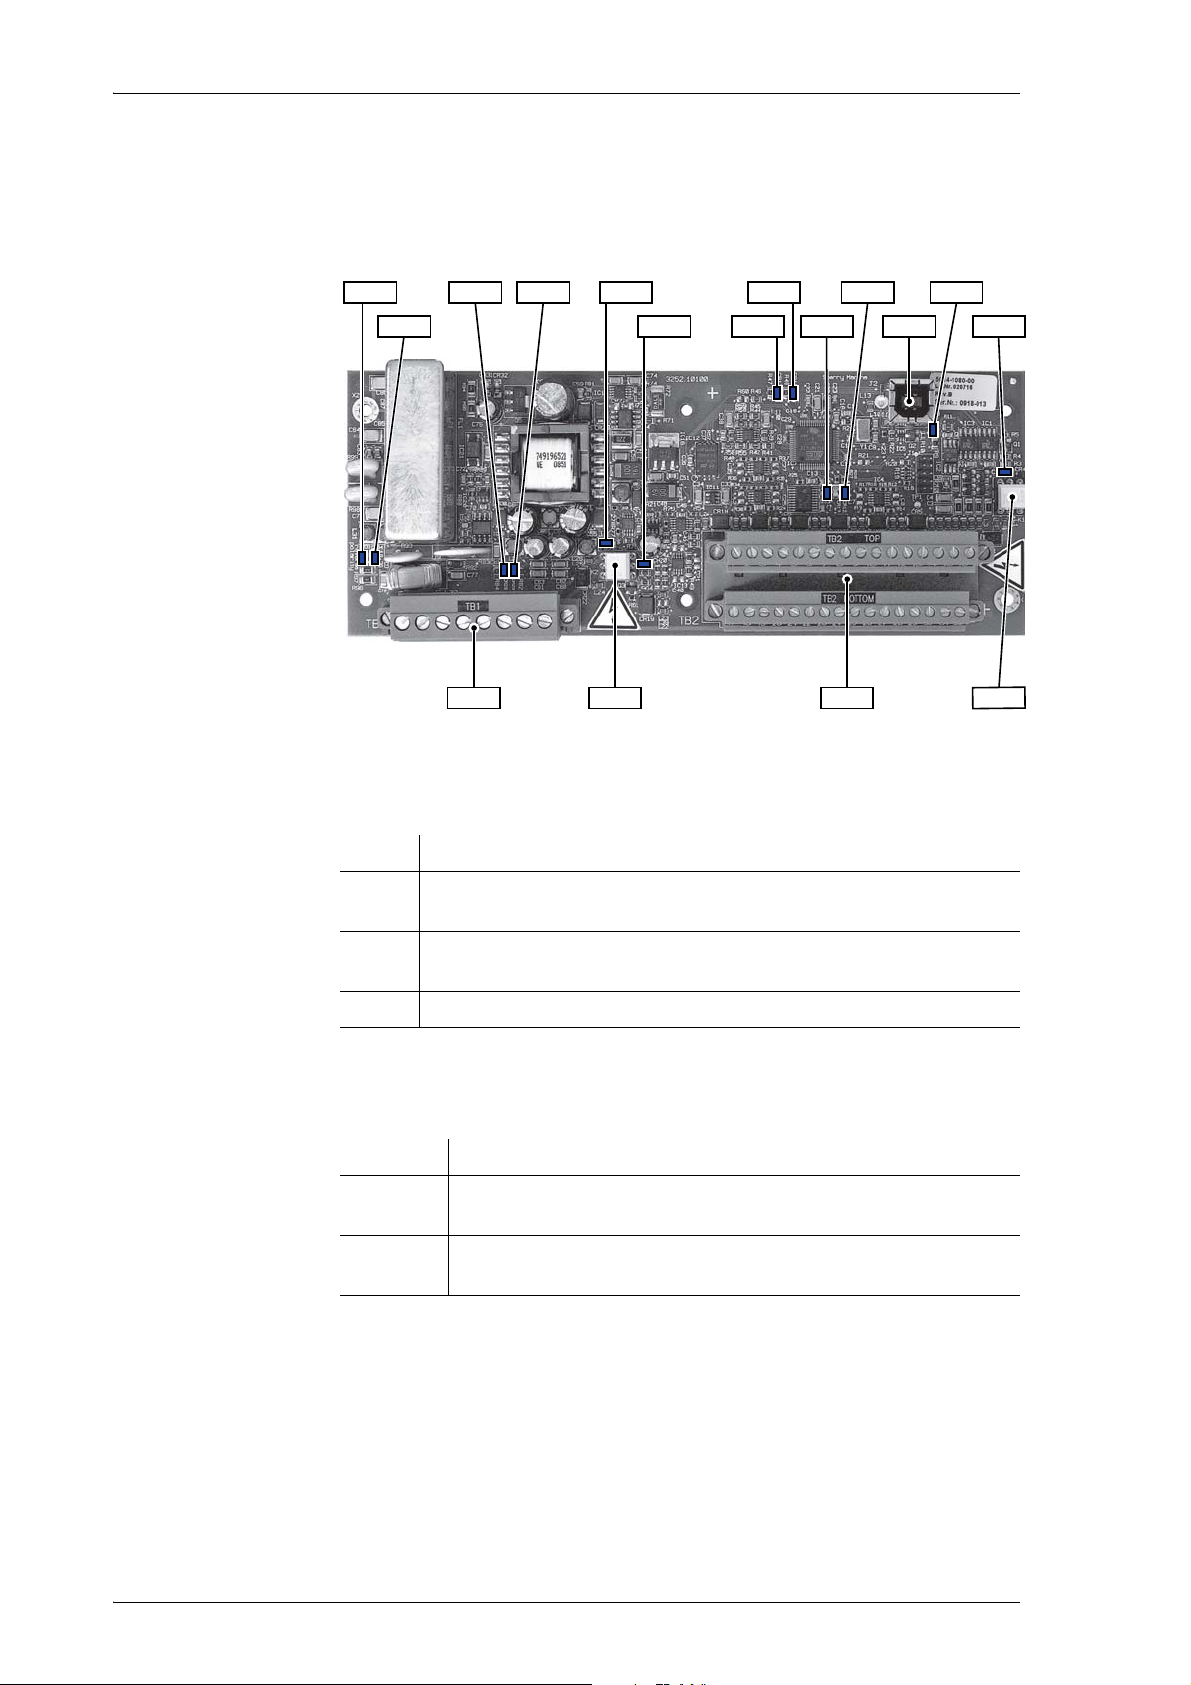
056357/B RAIS
TB 1 TB 2
CR 34 CR 20 CR 17 J 3 CR 4
CR 33 CR 29 CR 23 CR 16
CR 13
CR 12 CR 9CR 28
K 2
K 1
Location of Parts on the Rudder Angle Calibrator PCB
Figure 7-1 below shows the locations of connectors and diagnostic LED
indicators on the RAC.
Figure 7-1:
Location of parts
on the RAC PCB
Terminal Boards and Connectors
Table 7-1:
Terminal boards
and connectors
TB 1 24 VDC supply power in, feedback unit supply out, feedback
TB 2 RAI signal and illumination outputs, RS-422 in, RS-422 out 1
J 3 USB service interface connector
Function
signal in, “Pwr. Fail. / Gen. Alarm” status relay out
and 2, “Spare” status relay out
Exchangeable Components
Table 7-2:
Exchangeable
components
Part Function
K 1 photocoupler/photo relay;
“Spare” status output contact closure
K 2 photocoupler/photo relay;
“Pwr. Fail / Gen. Alarm” status output contact closure
7-2 General Troubleshooting Instructions
Page 57
RAIS 056357/B
Diagnostic LEDs
As an aid in troubleshooting, a number of diagnostic LED indicators are
provided on the PCB. These indicate the presence of supply voltages,
activities on the serial data I/O lines and the current states of the status
output ports.
Table 7-3:
Diagnostic LEDs
LED Colour Indication
CR 4 green relay status output “Spare”; on = relay attracted
CR 9 green activity on RS-422 input
CR 12 green system mode/status indication:
CR 13 green
CR 16 green activity on RS-422 output 1
CR 17 green activity on RS-422 output 2
CR 20 green relay status output “Power Fail. / Gen. Alarm”;
CR 23 green on-board +5 VDC power present
CR 28 green on-board +15 VDC power present
CR 29 green on-board –15 VDC power present
CR 33 red reversed polarity 24 VDC supply power
CR 34 green 24 VDC supply power present
both flashing: power-up in progress
both off: normal operation mode
both on: error reading setup data
on = relay attracted
General Troubleshooting Instructions 7-3
Page 58
056357/B RAIS
7-4 General Troubleshooting Instructions
Page 59
RAIS 056357/B
DANGER
CAUTION
Note
Note
Chapter 8: Corrective Maintenance
Life danger through electrical shock
Certain alarm devices may operate with hazardous voltages, switched
by the alarm relay output contacts.
NEVER connect live wires to the unit’s terminals, when wiring up the
Rudder Angle Calibrator.
ALWAYS make sure that any external device or power supply to be connected to the alarm relay outputs is de-energized and safeguarded
against accidental switching-on.
Risk of damage of electrostatic-discharge-sensitive components
The
Rudder Angle Calibrator contains electrostatic sensitive components.
Electrostatic discharge may permanently damage components.
When configuring the
electrostatic discharge. Avoid touching any of the electronic circuitry.
The Rudder Angle Calibrator is generally not field-serviceable on the component level. Defective devices must be sent back to Sperry Marine for
repair.
Rudder Angle Calibrator, take precautions to prevent
Maintenance by field service personnel is limited to the software-based
configuration and update procedures supported by the Sperry Universal
Software Instrument application (SUSI).
8.1 Updating the RAC Firmware with SUSI
Generally, it cannot be guaranteed that the Rudder Angle Calibrator’s
parameter settings are left intact during a firmware update.
Before updating firmware, record all parameter settings to be able to reenter them manually, if required.
Calibration settings will not be touched when updating the firmware.
For recording all parameter settings see “Setup and Configuration
Tables” in the appendix of this manual.
The RAC’s firmware may be updated in the field using SUSI.
Being a newer device, the RAC supports the uploading of firmware files.
This allows to selectively update either the actual RAC system software
(“MCU-Application”) or the RAC’s bootloader (“MCU-Bootloader”).
Compared to overwriting (“flashing”) the memory, as necessary with
older devices, the file upload is a much safer method to update a
device’s firmware, as SUSI is able to validate the provided files before
the upload. In case an upload should fail for any reason, the RAC will
remain fully functional, continuing to run the previous firmware.
In case a new firmware is released for the RAC, authorized field service
personnel will be provided with the required files upon request.
Updating the RAC Firmware with SUSI 8-1
Page 60
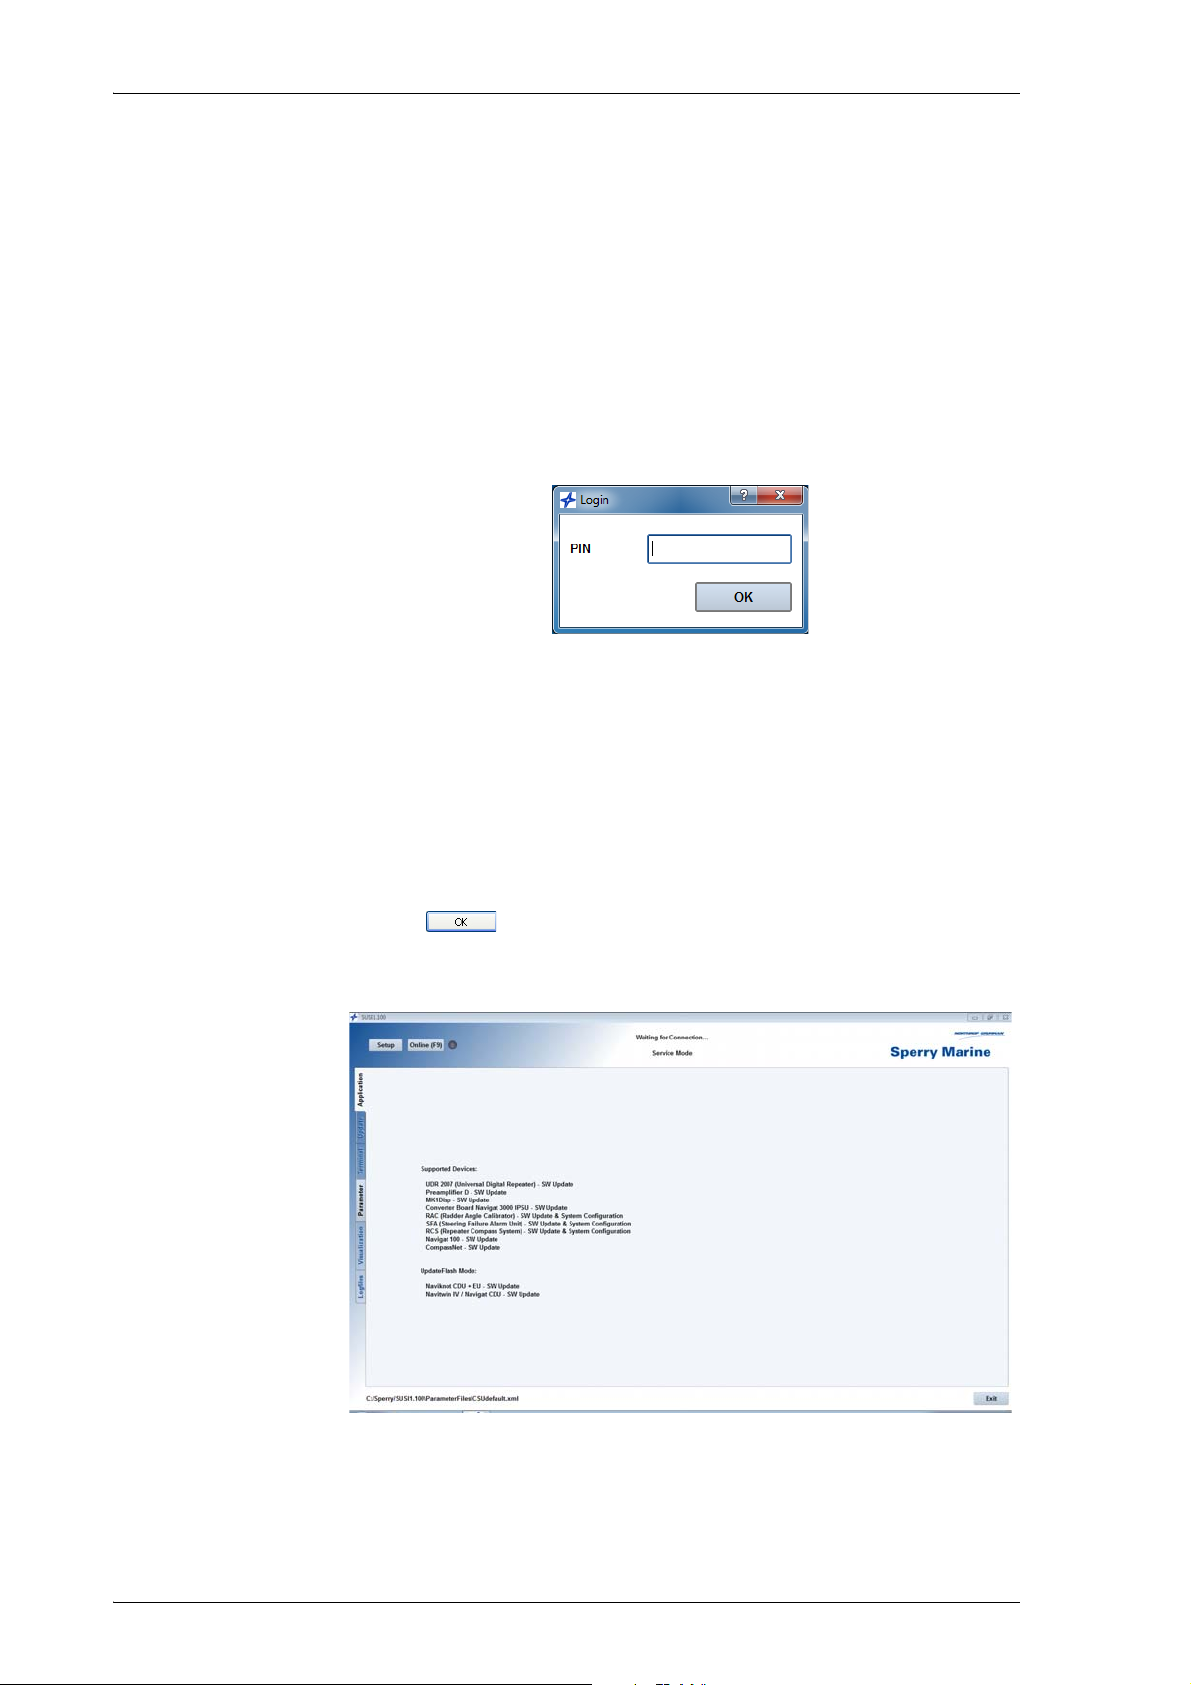
056357/B RAIS
Firmware files issued by Sperry Marine will usually be named such that
the filename identifies the device type and the firmware revision. The
file extension used for firmware files is “.upd”.
To update the Rudder Angle Calibrator firmware:
1. If the RAC is currently powered up, switch off the power first.
2. Open the RAC housing and locate the USB service port receptacle,
J3, on the PCB. Make sure that the port is freely accessible for plugging and unplugging the USB cable.
3. At the PC, start up the SUSI application.
A login dialog pops up:
4. You may either:
– Enter the PIN “20097”.
This will start up SUSI in the service mode.
Or:
– Leave the PIN empty.
This will start up SUSI in the “unknown login” mode.
In this mode, you may update the RAC firmware, but will not be
able to access the RAC’s configuration parameters without quitting and restarting SUSI in the service mode.
Click to continue.
5. SUSI’s main window now opens, with the “Application” tab displaying a list of supported devices:
6. Plug in the USB cable at the PC and at the RAC’s service port.
8-2 Updating the RAC Firmware with SUSI
Page 61
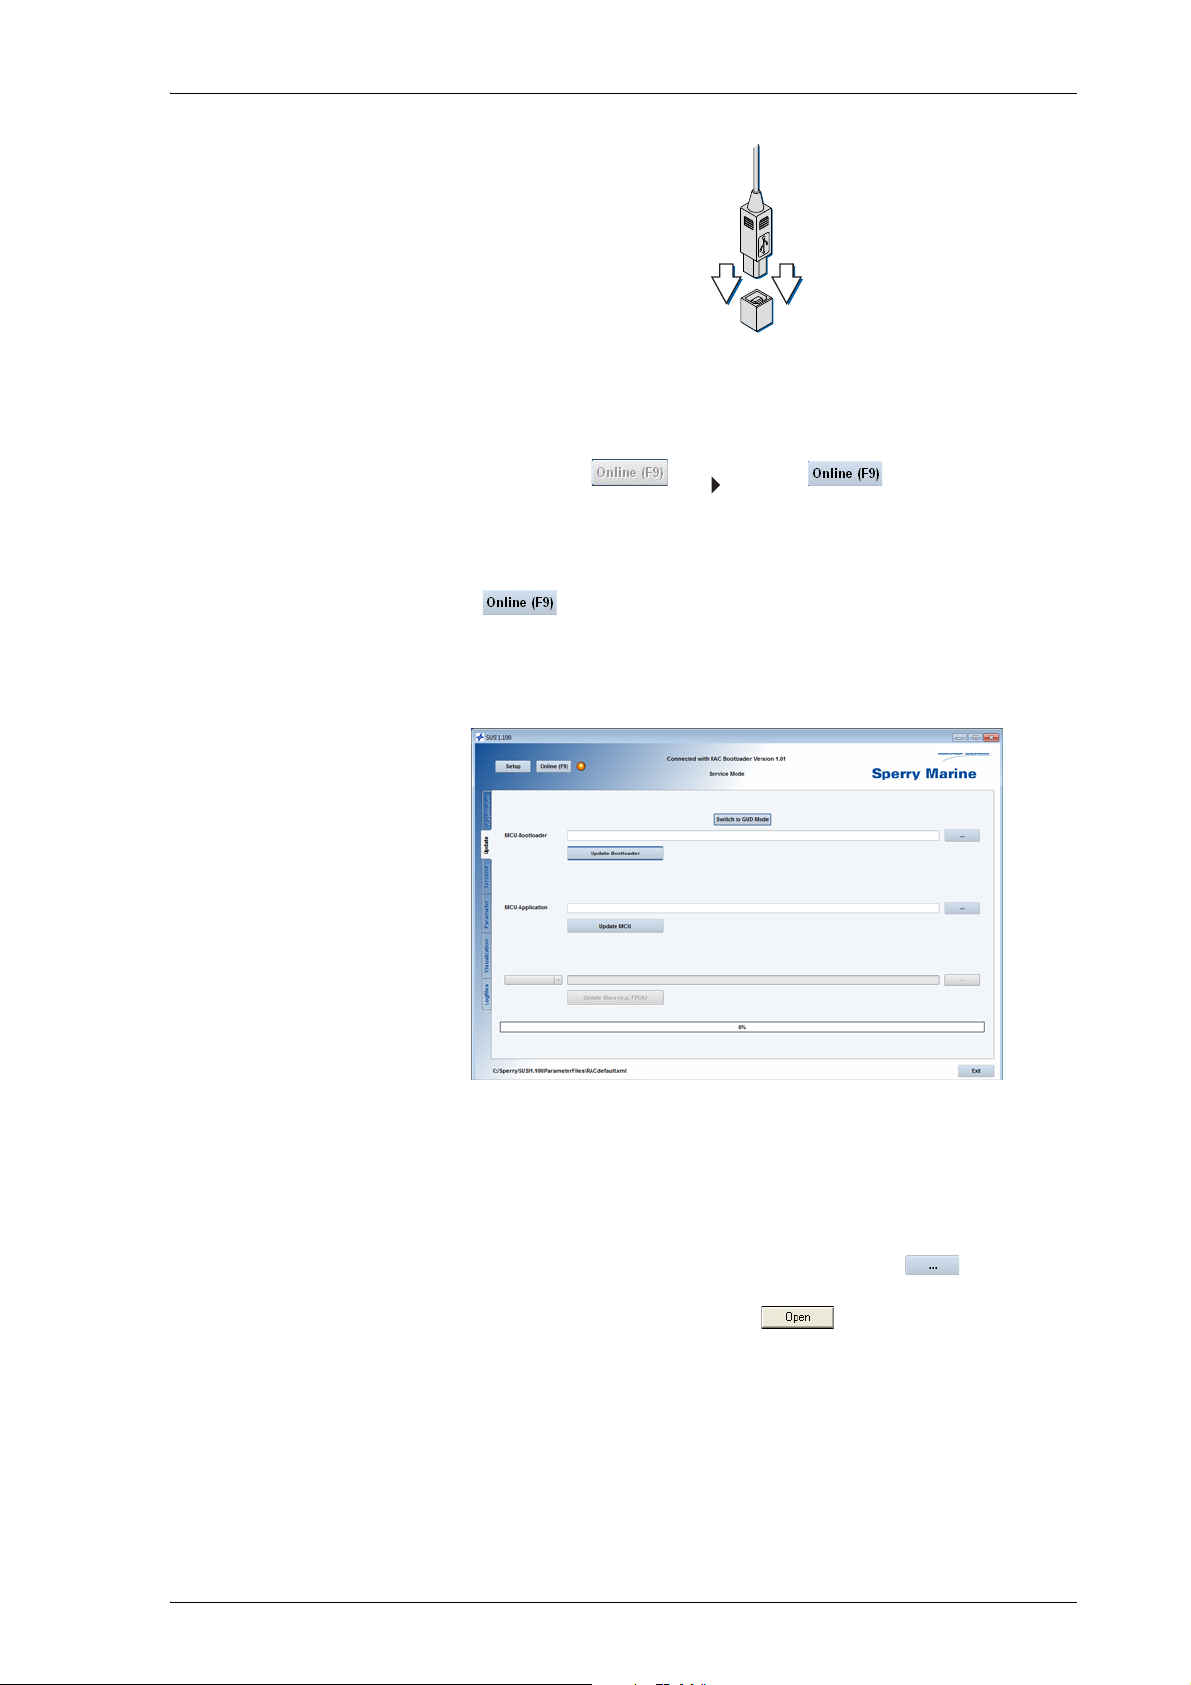
RAIS 056357/B
7. Power up the RAC.
The “Online” button should now become clickable (not greyed-out),
indicating that SUSI has found a device to connect to:
The LED icon next to the button will remain grey, as no connection
has been made yet.
8. Click to connect to the RAC.
The LED icon should now change to orange and the status line
should read “Connected with RAC Bootloader”.
Upon connecting, SUSI opens the update tab:
The update tab provides file browsers to select firmware update files
for the Rudder Angle Calibrator’s system software (“MCU-Application”) and the RAC’s bootloader (“MCU-Bootloader”).
The option to update program code for an FPGA (“FPGA-Application“) is greyed out, as the RAC does not contain an FPGA.
9. Depending on whether you intend to update the RAC’s MCU bootloader or its MCU application, click the respective button to
call up the file open dialog. Then, navigate to the firmware update
file, select it in the dialog and click .
Updating the RAC Firmware with SUSI 8-3
Page 62
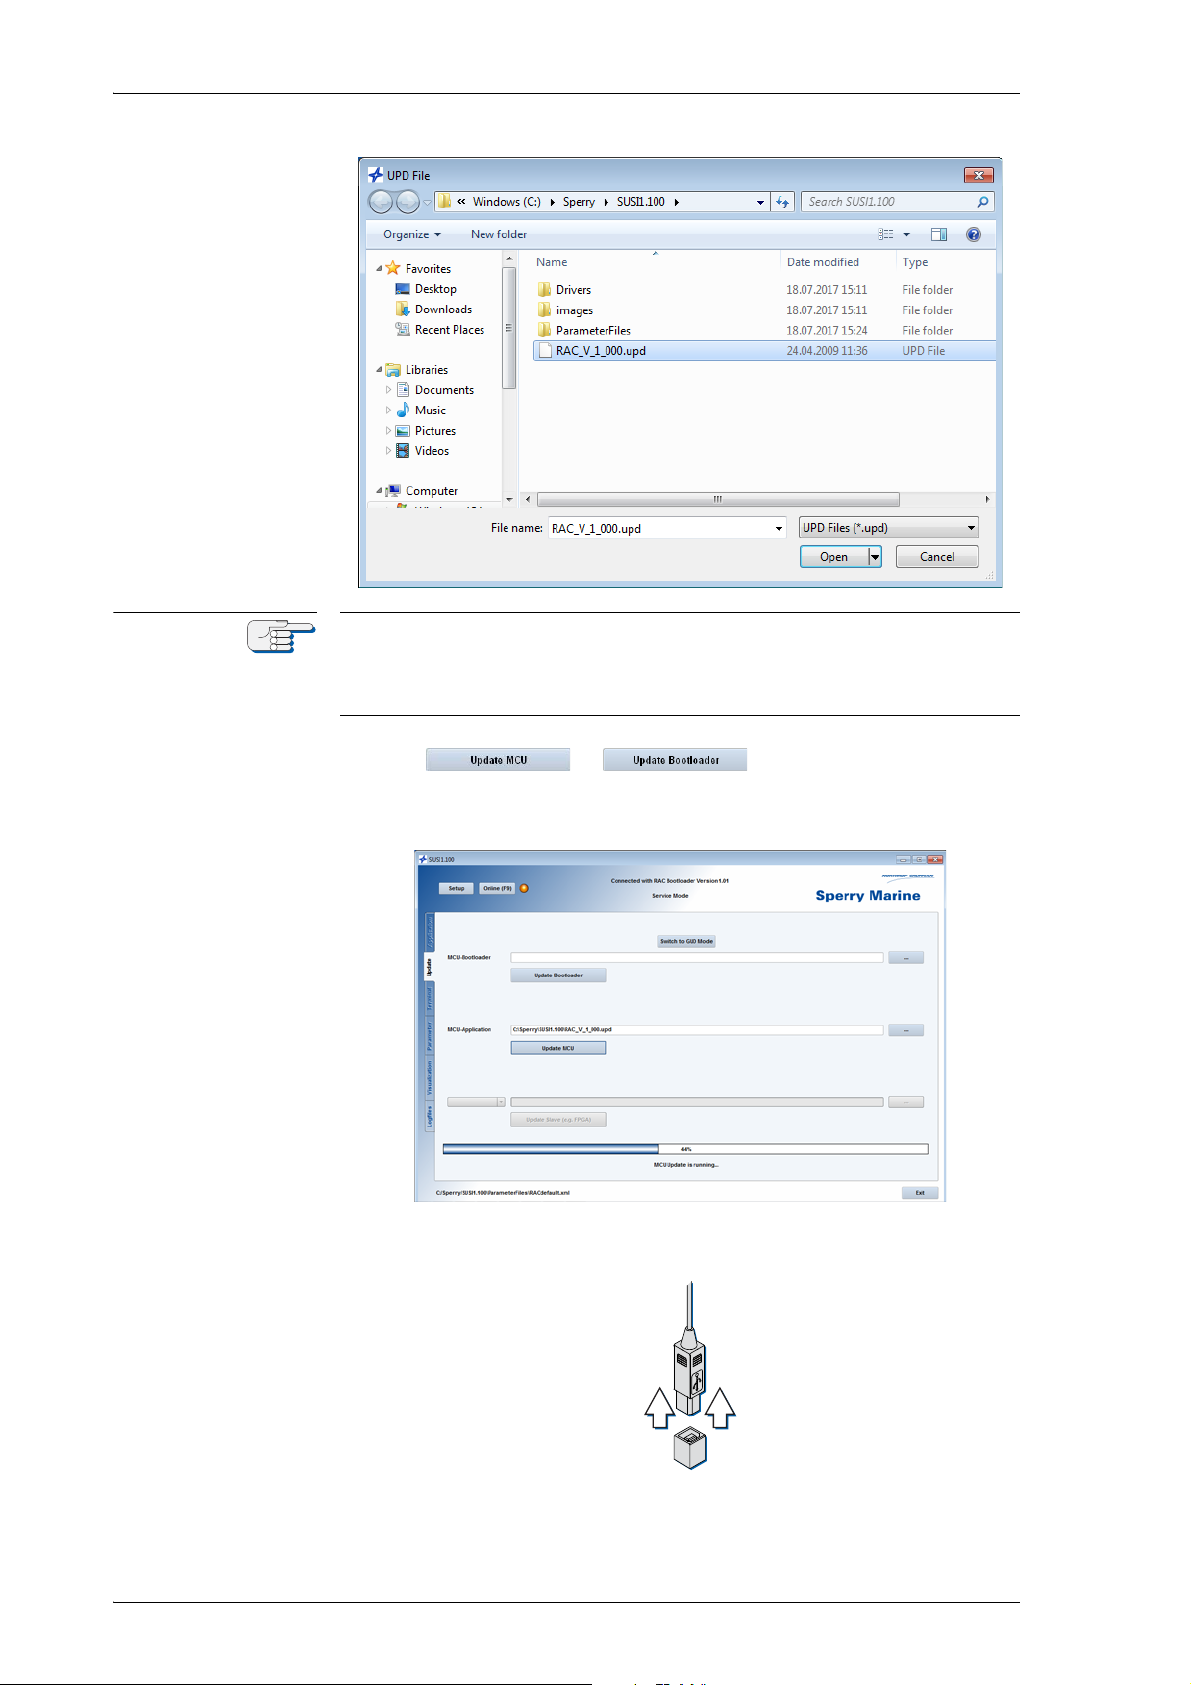
056357/B RAIS
Note
The file open dialogue searches for files with the extension ”.upd” only.
In case the update file has been given another extension for any reason,
the filename, including the complete access path, must be entered manually in the respective text box of the update tab.
10. Click or respectively to initiate the
actual file upload. The bargraph at the bottom of the screen indicates
the progress of the update:
11. When the update is complete, unplug the USB cable at the PC and at
the RAC’s service port.
12. The RAC now reboots with the new firmware.
8-4 Updating the RAC Firmware with SUSI
Page 63
RAIS 056357/B
8.2 Replacing Alarm Output Relays
The alarm output relays, K1 and K2, are socketed solid state relays in a
6-pin DIL package. In case of failure, these components can easily be
replaced against a new ones.
Both relays are photocoupler photo relays (TLP 598GA), available from
Sperry Marine Hamburg upon request.
Replacing Alarm Output Relays 8-5
Page 64
056357/B RAIS
8-6 Replacing Alarm Output Relays
Page 65
RAIS 056357/B
Note
Abbreviations
The following list contains abbreviations and shortcuts used in this manual and in displayed text of CDU menus.
A
1x1 frame Standard frame 96x96 mm
6 step/° scale measure setting of servomotor
A/DO-160 Section A, DO-160E, Environmental Conditions and
Test Procedures for Airborne Equipment
ACK Acknowledge alarms
ADA Name of a Programming Language
AIS Automatic Identification System
ALR NMEA sentence for alarm status information
AMS Alarm Management System
ANSI American National Standards Institute
approx. Approximately
ARS Attitude Reference System
ASME American Society of Mechanical Engineers
AZ Azimuth
B
BD Baud
Bd. Baud
BIT Built In Test
BIU Bus interface unit
BSH German Federal Maritime and Hydrographic Agency
btl. Bottle
(BSH)
C
CCelsius
CA Correction Angles
CAB Compass Amplifier Board
CAU Compass Amplifier Unit
Abbreviations I
Page 66
056357/B RAIS
CAL. Calibration
CAM Central Alert Management
cal. no. s. Calibration numbers
CCFL Cold Cathode Fluorescent Lamp
CCU Compass Controller Unit processor
CDU Control and Display Unit
CN CompassNet
CN Ringbus CompassNet Ethernet Bus
CNET CompassNet
COG Course over ground
COMP Compass
Comp. Mon. Compass monitor
CONST. Constant
contd. Continued
CORR. Correction
cos. Cosine
CR Carriage return
CSU Compass Sensor Unit processor
D
D00 D00 - D32 (D-Code, = Fault code)
DAC Digital analogue converter
DC Direct Current
D-Code Fault code (D00 - D32)
DDU Data Distribution Unit
DGPS Differential GPS (see also GPS)
dia. Diameter
diff. Difference
DIFF. Difference
DIM dimmer
DIN Deutsches Institut für Normung (German institute for
standardization)
Dnn D00 - D32 (D-Code, = Fault code)
II Abbreviations
Page 67
RAIS 056357/B
DNV Det Norske Veritas
DNV Naut-AW Det Norske Veritas Class notation for enhanced nauti-
cal safety
DP Dynamic positioning
dwg. drawing
E
E. East
EC European Union Council
ECCN Export Control Classification Number
ECDIS Electronic Chart Display and Information System
EMC Environmental conditions
EM-Log Electromagnetic (speed) log
EN European Norm
ERR.STAT.BITS Validity check of fiber-optic sensor data status
ESD electrostatic discharge
ext. External
Ext. External
Ext. Sel. External selector switch
Ext Status In External status input port (TB 3.11)
F
FIU Fiber optic interface unit (synonym for IPSU)
FL Line filter
Flash Nonvolatile Memory
FMEA Failure mode effect analysis
FOG Fiber optic gyro
FPGA Field-programmable gate array
FRAM Ferro Electrical RAM (Non volatile RAM)
FU Follow up
Abbreviations III
Page 68
056357/B RAIS
G
G1 Gyrocompass 1
G2 Gyrocompass 2
G/M headings Gyro /Magnetic headings
GAS Grounding avoidance system
Gen. General
GGA NMEA sentence which provides the GPS current fix
data.
GL Germanischer Lloyd
GLL Geographic position - latitude/longitude
GMDSS Global Maritime Distress and Safety System
Gnd Ground
GNSS Global Navigation Satellite System
GPS Global Positioning System
GPS Global Positioning System
GPS/AIS Global Positioning System / Automatic Identification
System
GSR Gyrosphere service report
GT Gross tonnage
H
HCS Heading control system
HDG Heading, Magnetic
Hdg. Heading
hdg. Heading
Hdg. Diff Heading Difference Alarm
Hdg. Sel Heading selection; Selection of heading source device
Hdg. Sel. Heading selection
HDG/G Heading/Gyro
HDT Heading, True
HMS Heading management system
HSC High speed craft
HSC-2000 Class notation for high speed craft
HTC Heading track control command
IV Abbreviations
Page 69
RAIS 056357/B
HTD Heading track control data
Hz Hertz
I
I/O Input/Output
IC Integrated circuit
ICD Interface Control Document
ID Identifier
IEC International Electro Technical Commission
IHO International hydrographic office.
IMO International Maritime Organization
IMU Inertial Measurement Unit
INS Integrated navigation system
INT HDG ONLY Internal heading only
INT/EXT HDG Internal or external heading
IP International Protection
IPD Illustrated Parts Data
IPL Illustrated Parts List
IPSU Interface and power supply unit
ISO International Organization for Standardization
J
J Jack (connector)
K
KF Kalman Filter
Kt. Knot
kt. Knot
L
LAT Latitude
Lat. Latitude
Abbreviations V
Page 70
056357/B RAIS
lat. Latitude
LCD Liquid crystal display
LED Light Emitting Diode
LEHMK Lehmkuhl (transmission standard company Lehm-
kuhl)
LF Line feed
LFK Litef Faser Kreisel (Litef fiber optic gyroscope)
lon. Longitude
Lon. Longitude
LORAN Long Range Navigation
LORAN-C Long Range Navigation C
LSB Least significant Bit
M
Mag Magnetic
Mag Hdg. Inp. Magnetic heading input
MAGN. Magnet
Magn. Cal. Tab Magnetic compass calibration table
Magn. DEV Magnetic deviation
Magn. VAR Magnetic variation
MAN. Manually
MarED Marine Equipment Directive
max. Maximal
MED Marine Equipment Directive
MIN Minute
min Minute
min. Minimal
MMS Mechanical mode switch
Mod. Model
Mod. Modus
Mod. 10/2 Gyrocompass container model 10/2
Mod. 10/3 Gyrocompass container model 10/3
Mod. 7/2 Gyrocompass container model 7/2
VI Abbreviations
Page 71
RAIS 056357/B
MSB Most significant Bit
MSC Maritime Safety Committee
MTBF Mean time between failure
N
N. North
NAUT-AW Class notation with augments requirements for bridge
congfiguration for ships largely operating largely in
coastal and narrow waters
NAUT-HSC Class notation for high speed craft
NAUT-OC Class notation with fundamental requirements for
ships largely operating largely at high seas
NAUT-OSV Class notation with requirements for ships largely
operating as support vessels for various offshore
operations.
Nav. Navigation
n.c. Normally closed
NC Normally closed
NFU None follow up
NG NAVIGAT
NG 100 NAVIGAT 100
NG 200 NAVIGAT 200
nm Nautic mile
NM Nautic mile
NMEA National Marine Electronics Association
NMEA NMEA format 4800 Bd
NMEA $--HDG NMEA $--HDG sentence
NMEA $--HDM NMEA $--HDM sentence
NMEA $--HDT NMEA $--HDT sentence
NMEA Sup.FAST SuperFAST serial data output
NMEA-GGA NMEA-GGA sentence
NMEA-GLL NMEA-GLL sentence
NMEA-HCHDG NMEA-HCHDG sentence
NMEA-HCHDM NMEA-HCHDM sentence
NMEA-HCHDT NMEA-HCHDT sentence
NMEA-HDG NMEA-HDG sentence
Abbreviations VII
Page 72
056357/B RAIS
NMEA-HDM NMEA-HDM sentence
NMEA-RMA NMEA-RMA sentence
NMEA-RMC NMEA-RMC sentence
n.o. Normally open
NO Normally open
No. Number
NVR None Volatile RAM
O
Off Hdg Off heading alarm
OUTP Output
P
p. Pulse
P.Gnd Power ground
P/N Part number
PAL Pre-programmed IC
PCB Printed circuit board
PLATH Binary protocol of company C. Plath
PLCC Plastic leaded chip carrier
POS Position
POSITION N No position
PPE Personal protective equipment
PSU Power Supply Unit
PSR Product service report
Q
QUICC Quad Integrated Communications Controller
QUART Quad Universal Asynchronous Receiver and Transmit-
ter
VIII Abbreviations
Page 73
RAIS 056357/B
R
RAC Rudder angle calibrator
RAFU Rudder angle feedback unit
RAI Rudder angle indicator
RAIs Rudder angle indicators
RAIS Rudder angle indicator system
RAM Random Access Memory
Ref. Voltage Reference voltage
RM Recommended minimum navigation information
RMA Recommended minimum navigation information
NMEA sentence A
RMB Recommended minimum navigation information
RMC Recommended minimum navigation information
RMS Root mean square
NMEA sentence B
NMEA sentence C
ROM Read Only Memory
ROR Rudder order status
ROT Rate of turn
ROTI Rate of turn indicator
rpm Revolutions per minute
RS-422 RS-422 serial data interface standard
RSA NMEA sentence for rudder set angle
RUD rudder angle graph
S
S. South
s Second
S/FAST M. Outp. Superfast / fast data output of magnetic heading
SAT-Log Satellite (speed) log
sc. Factor Scale factor
SCU Steering control unit
SEC Second
sec Second
SENS.D.M.OUTP. Output sentence format for magnetic heading at the
sensor data output
Abbreviations IX
Page 74
056357/B RAIS
Sentence A self-contained line of data
SFA unit Steering failure alarm unit
sin. Sine
SMS Steering mode switch
SOG Speed over ground (actual measured speed of
advance of a vessel over the surface of the earth)
SOLAS Safety of life at sea
SoS Scope of supply
SOU Switch-over unit
SPEED N No speed
SRAM Static RAM
SRD Abbreviation for speed log
Stat. Status
stb. Starboard
STW Speed through water (ship's speed, as measured rela-
tive to the water).
SUSI Sperry universal service instrument
SVDR Simplified voyage data recorder
T
TB TB 3.11 (external input port)
TB Terminal block
THS True heading and status
THS Transmitting heading system
TMC Transmitting magnet compass
TMC function Transmitting magnet compass function
TSS1 TSS1 protocol; Heading, pitch, roll, and heave mes-
sage in the commonly used TSS1 message format
TTL Transistor-transistor-logic
TxD NMEA FAST Fast serial data output
U
UART Universal asynchronous receiver transmitter
UDR Universal digital repeater
X Abbreviations
Page 75
RAIS 056357/B
UML Unified Modelling Language
USCG United states coast guard
V
VVolt
VAC Volt alternating current
VDC Volt direct current
VDR Voyage data recorder
VHW Water speed and heading
VMS Voyage management system
VMS/ECDIS Voyage management system / electronic chart display
and information system
VOSS Vessel optimization & safety system
Vpp. Voltage peak to peak
VTG Velocity through ground
VTS Vessel traffic service
W
WWatt
W. West
w. with
w/ with
W/DO-160 Section W, DO-160E, Environmental Conditions and
Test Procedures for Airborne Equipment
w/o without
X
X rate Roll rate
X/Y rates Roll and pitch rates
Y
Y rate Pitch rate
Abbreviations XI
Page 76
056357/B RAIS
Z
Z/DO-160 Section Z, DO-160E, Environmental Conditions and
Test Procedures for Airborne Equipment
XII Abbreviations
Page 77
RAIS 056357/B
Note
Note
Appendix
The following documents and drawings are appended to this manual:
A Setup and Configuration Tables
Designation Drawing No.
RAC Setup table (blank form) 5014-0125-001
After installation of the Rudder Angle Calibrator, please return a filled-out
copy of the Setup Table to Sperry Marine for inclusion in the ship’s file.
When permanent changes are made to the system configuration, please
return an updated copy of the Setup Table to Sperry Marine.
B Third party Documentation
Designation Drawing No.
Faiveley Mors Smitt Rudder Angle Indicators,
Installation instructions
All content of the appended third party documentation is on behalf of the
owners of the documentation. Sperry Marine is not responsible and not
liable for any content of third party documentation.
In case of doubt, verify the content of third party documentation with the
owners of the documentation.
2017-07-03
Page 78
056357/B RAIS
Note
CDrawings
Designation Drawing No.
RAC, Dimension Drawing 5014-0112-01
RAC, Circuit Diagram 5014-0115-01
Rudder Angle Feedback Unit, Dimension Drawing 4968-0112-01
Rudder Angle Feedback Unit, Option Linkage rod,
Dimension Drawing
Rudder Angle Feedback Unit, Telemotor,
Dimension Drawing
Rudder Angle Feedback Unit, Option Linkage Rod,
Dimension Drawing
Rudder Angle Indicator System, Single Rudder,
up to 6 indicators (Standard Connection Drawing)
Rudder Angle Indicator System, Single Rudder,
more than 6 indicators
(Standard Connection Drawing)
Rudder Angle Indicator System, Dual Rudder
(Standard Connection Drawing)
All appended documents and drawings are revision-controlled separately at Sperry Marine.
In case of doubt, verify the current revision status of the drawings with
Sperry Marine. This manual’s revision status does not change when the
revision of an appended document or drawing changes.
4968-0112-02
4968-0112-03
4968-0112-04
5014-0153-11
5014-0153-13
5014-0153-15
Page 79
Rudder Angle Calibrator (RAC)
Setup Table
Vessel:
IMO No.:
Service Station / Installer: Date / Signature:
Hull No.:
Shipyard:
/
Installation Reference
RAC Serial Number:
Feedback Type
single rudder
Serial I/O
RS-422 In
Baudrate
4800
9600
38400
Location:
System Parameter Settings
starboard rudder
RS-422 Out 1
Baudrate
4800
9600
38400
Update Rate
Software Version:
port rudder
10 Hz
1 Hz
005014-0125-001/B; 26 Jun 2017; Page 1 of 4
Messages
RSA
CAUTION
Relay Setup
General Alarm
closed on no alarm
closed on alarm
Messages
RSA
RS-422 Out 2
Baudrate
4800
9600
38400
Messages
RSA
ALR
Risk of misusage
The ALR sentence as serial output of the RAC is not
therefore NOT allowed as system setting for a ship under wheelmark
certification
Always make sure that the ALR sentence setting is INACTIVATED when
the RAC is used on a ship under wheelmark certification.
Spare
closed on no alarm
closed on alarm
Update Rate
10 Hz
1 Hz
MED complaint and
Northrop Grumman Sperry Marine B.V. (Representative Office)
Woltmanstr. 19, 20097 Hamburg, Germany
Tel.: +49-40-29900-0, Fax: +49-40-29900-146, E-mail: [email protected]
Page 80
Rudder Angle Calibrator (RAC)
Input Calibration Table
Setup Table
Rud. Angle
1
3 4
5 6
7 8
9 10
11 12
13 14
15 16
17 18
19 20
21 22
23 24
25 26
27 28
29 30
31 32
33 34
A/D Digits
Rud. Angle
2
A/D Digits
005014-0125-001/B; 26 Jun 2017; Page 2 of 4
35 36
37 38
39 40
41 42
43 44
45 46
47 48
49 50
51 52
53 54
55 56
57 58
59 60
61 62
63 64
65 66
67 68
69 70
71 72
73
Northrop Grumman Sperry Marine B.V. (Representative Office)
Woltmanstr. 19, 20097 Hamburg, Germany
Tel.: +49-40-29900-0, Fax: +49-40-29900-146, E-mail: [email protected]
Page 81
Rudder Angle Calibrator (RAC)
Output Calibration Table
Setup Table
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
35
36
1
2
3
4
5
6
7
8
9
Rudder
Angle
Digits
Out 1
Digits
Out 2
Digits
Out 3
Digits
Out 4
Digits
Out 5
Digits
Out 6
005014-0125-001/B; 26 Jun 2017; Page 3 of 4
Northrop Grumman Sperry Marine B.V. (Representative Office)
Woltmanstr. 19, 20097 Hamburg, Germany
Tel.: +49-40-29900-0, Fax: +49-40-29900-146, E-mail: [email protected]
Page 82
Rudder Angle Calibrator (RAC)
Setup Table
Output Calibration Table (continued)
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
69
70
71
72
73
Rudder
Angle
Digits
Out 1
Digits
Out 2
Digits
Out 3
Digits
Out 4
Digits
Out 5
Digits
Out 6
005014-0125-001/B; 26 Jun 2017; Page 4 of 4
Northrop Grumman Sperry Marine B.V. (Representative Office)
Woltmanstr. 19, 20097 Hamburg, Germany
Tel.: +49-40-29900-0, Fax: +49-40-29900-146, E-mail: [email protected]
Page 83
Installation instructions
Rudder Angle Indication Systems
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 1
Page 84
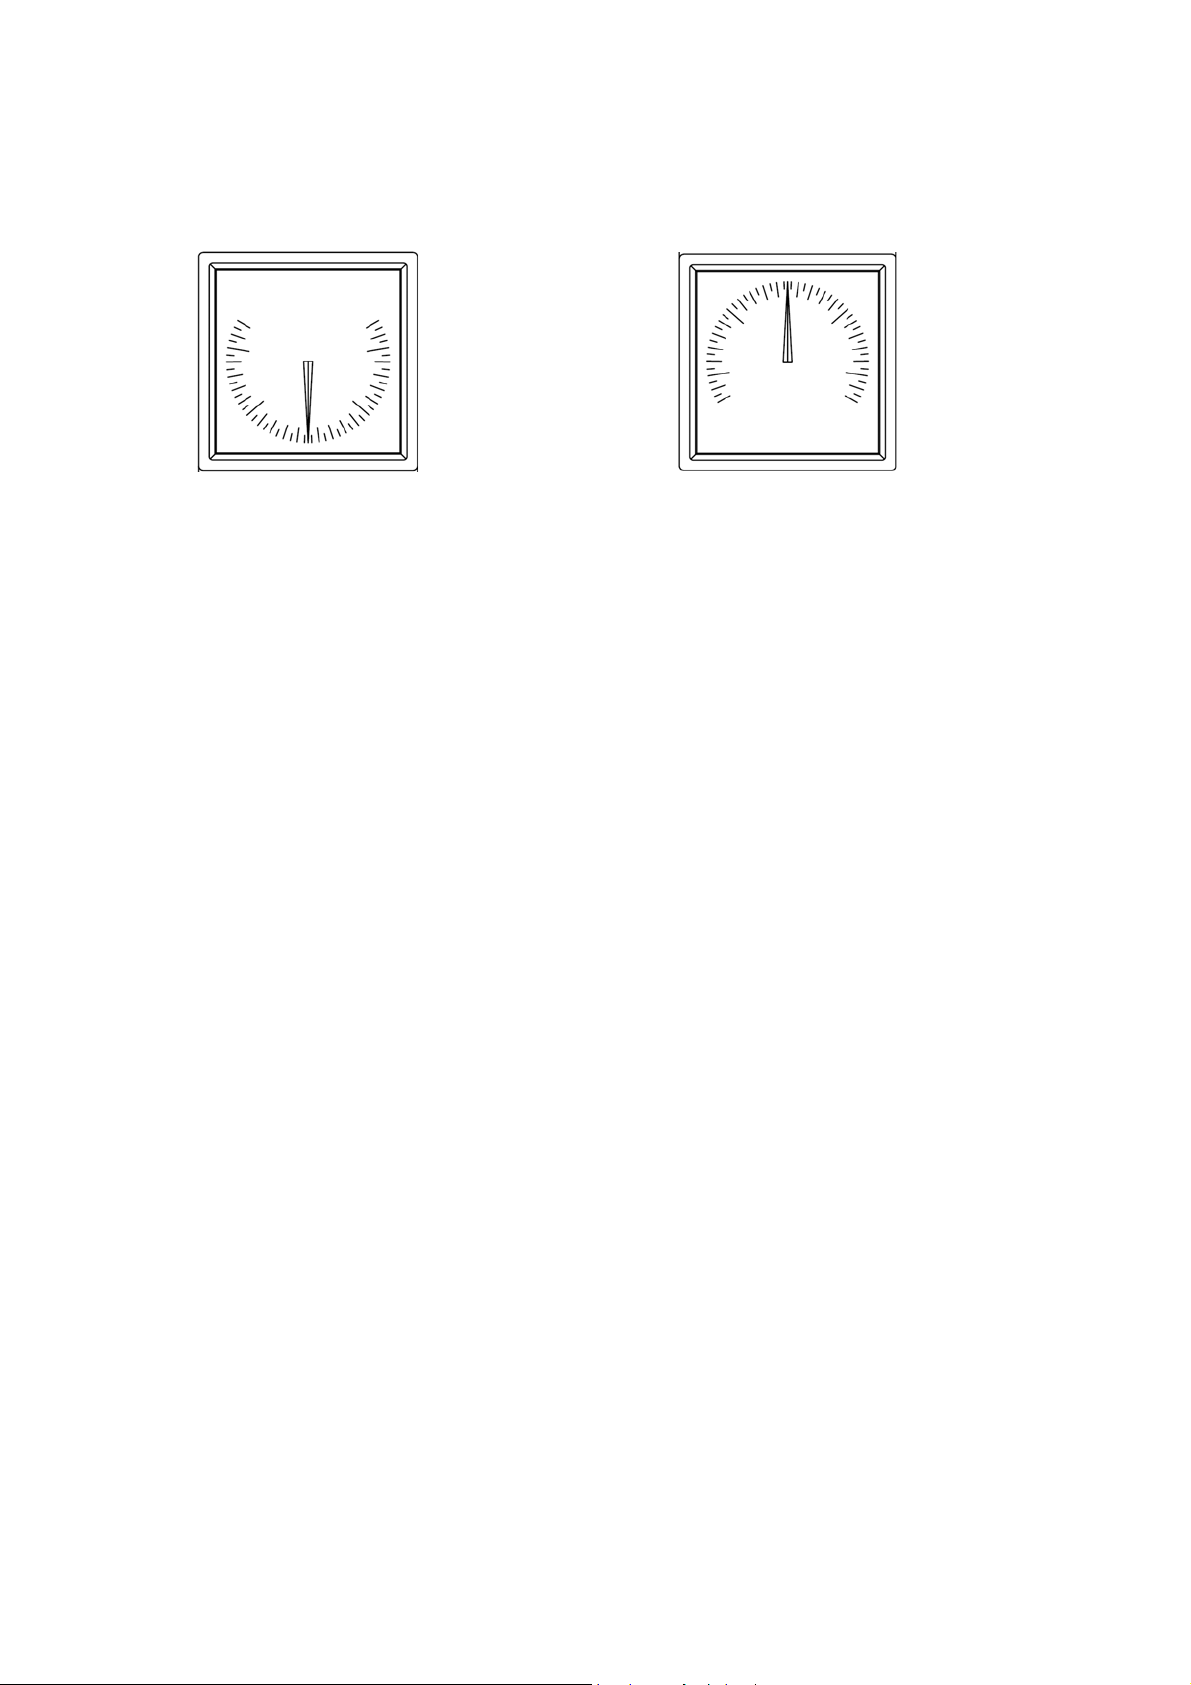
Console mounting:
Frontsize: 96x96:
060334-0000-000 Range ±45°
060335-0000-000 Range ±70°
Frontsize: 144x144:
060338-0000-000 Range ±45°
060339-0000-000 Range ±70°
Frontsize: 192x192:
060352-0000-000 Range ±45°
060353-0000-000 Range ±70°
060331-0000-000 Range ±45
060337-0000-000 Range ±70°
060340-0000-000 Range ±45°
060341-0000-000 Range ±70°
060354-0000-000 Range ±45°
060355-0000-000 Range ±70°
PANAMATYPE
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 2
Page 85
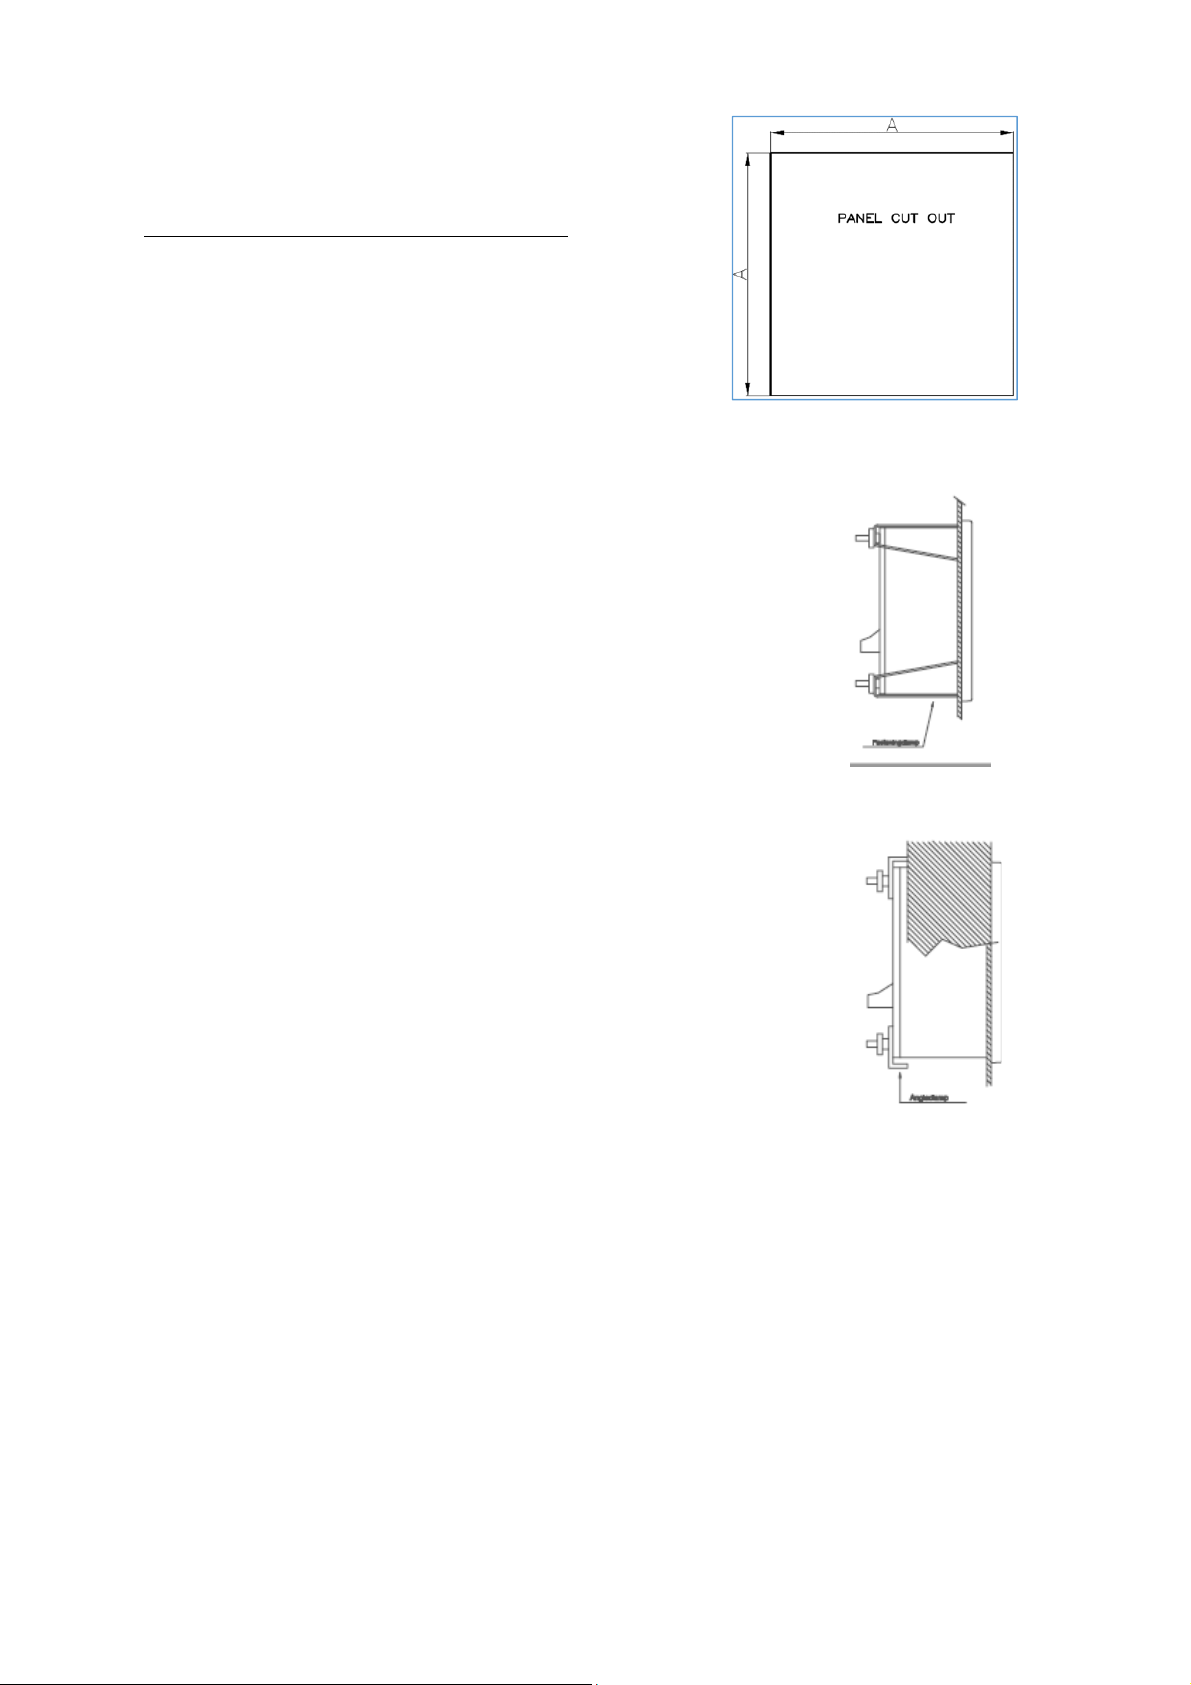
Panel-cutout:
Frontsize: Dimensions (mm)
“A”
96x96 92
144x144 138
192x192 186
+0.8
+1
+1
Mounting withe fastening clamp:
Mounting withe angleclamp:
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 3
Page 86
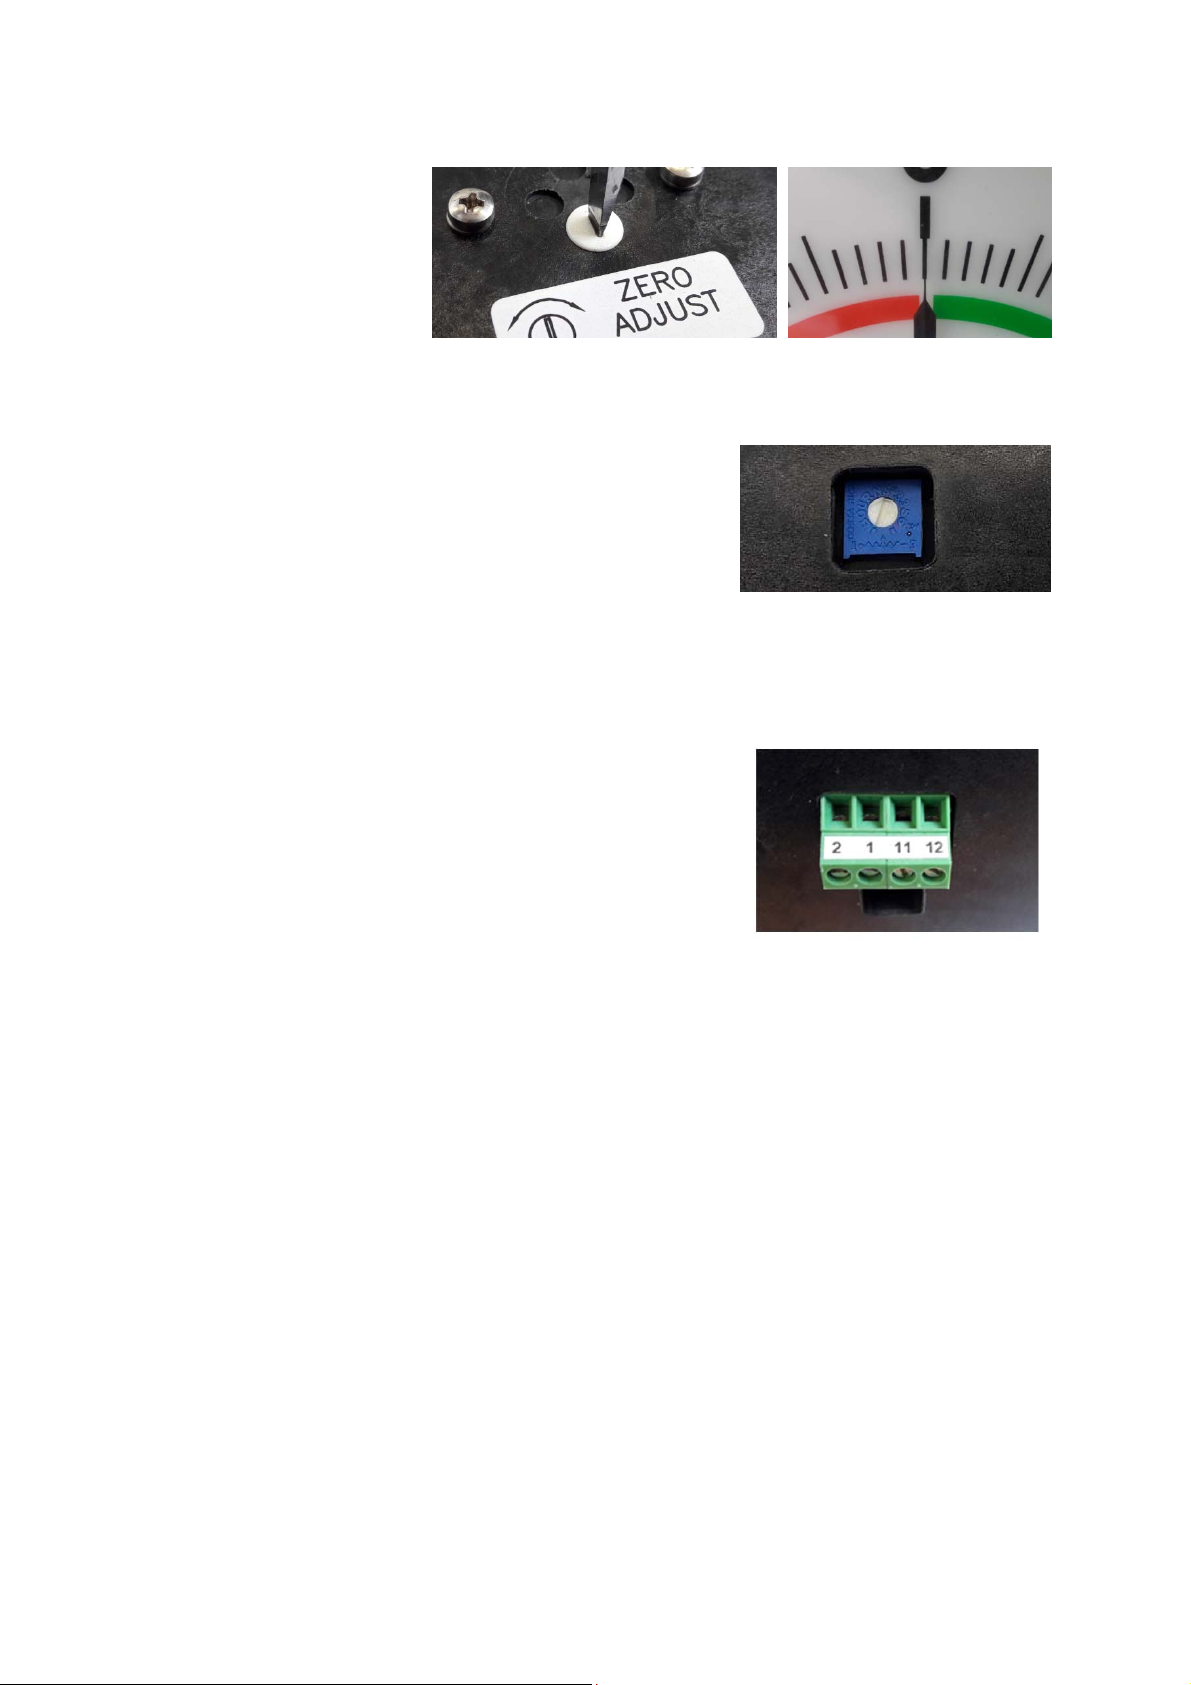
Zero adjustment:
At the back of the indicator is a
small “screw”. Turn gently with a
well-fitting screwdriver to left or
right (max +/-30°) to adjust the
pointer to zero on the scale.
Span adjustment:
At the back of the meter is a small blue potentiometer.
This is intended for the adjustment of the span of the meter.
Apply the signal and turn this pot to set the pointer on the desired
position.
Terminals:
The instrument has four terminals for input
1 = + signal
2 = - signal
11 = illumination
12 = illumination.
The illumination has no preferred polarity.
The min/max wires sizes are 0,14-2.5 mm
2
(26-14 AWG).
For solid or flexible wire.
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 4
Page 87
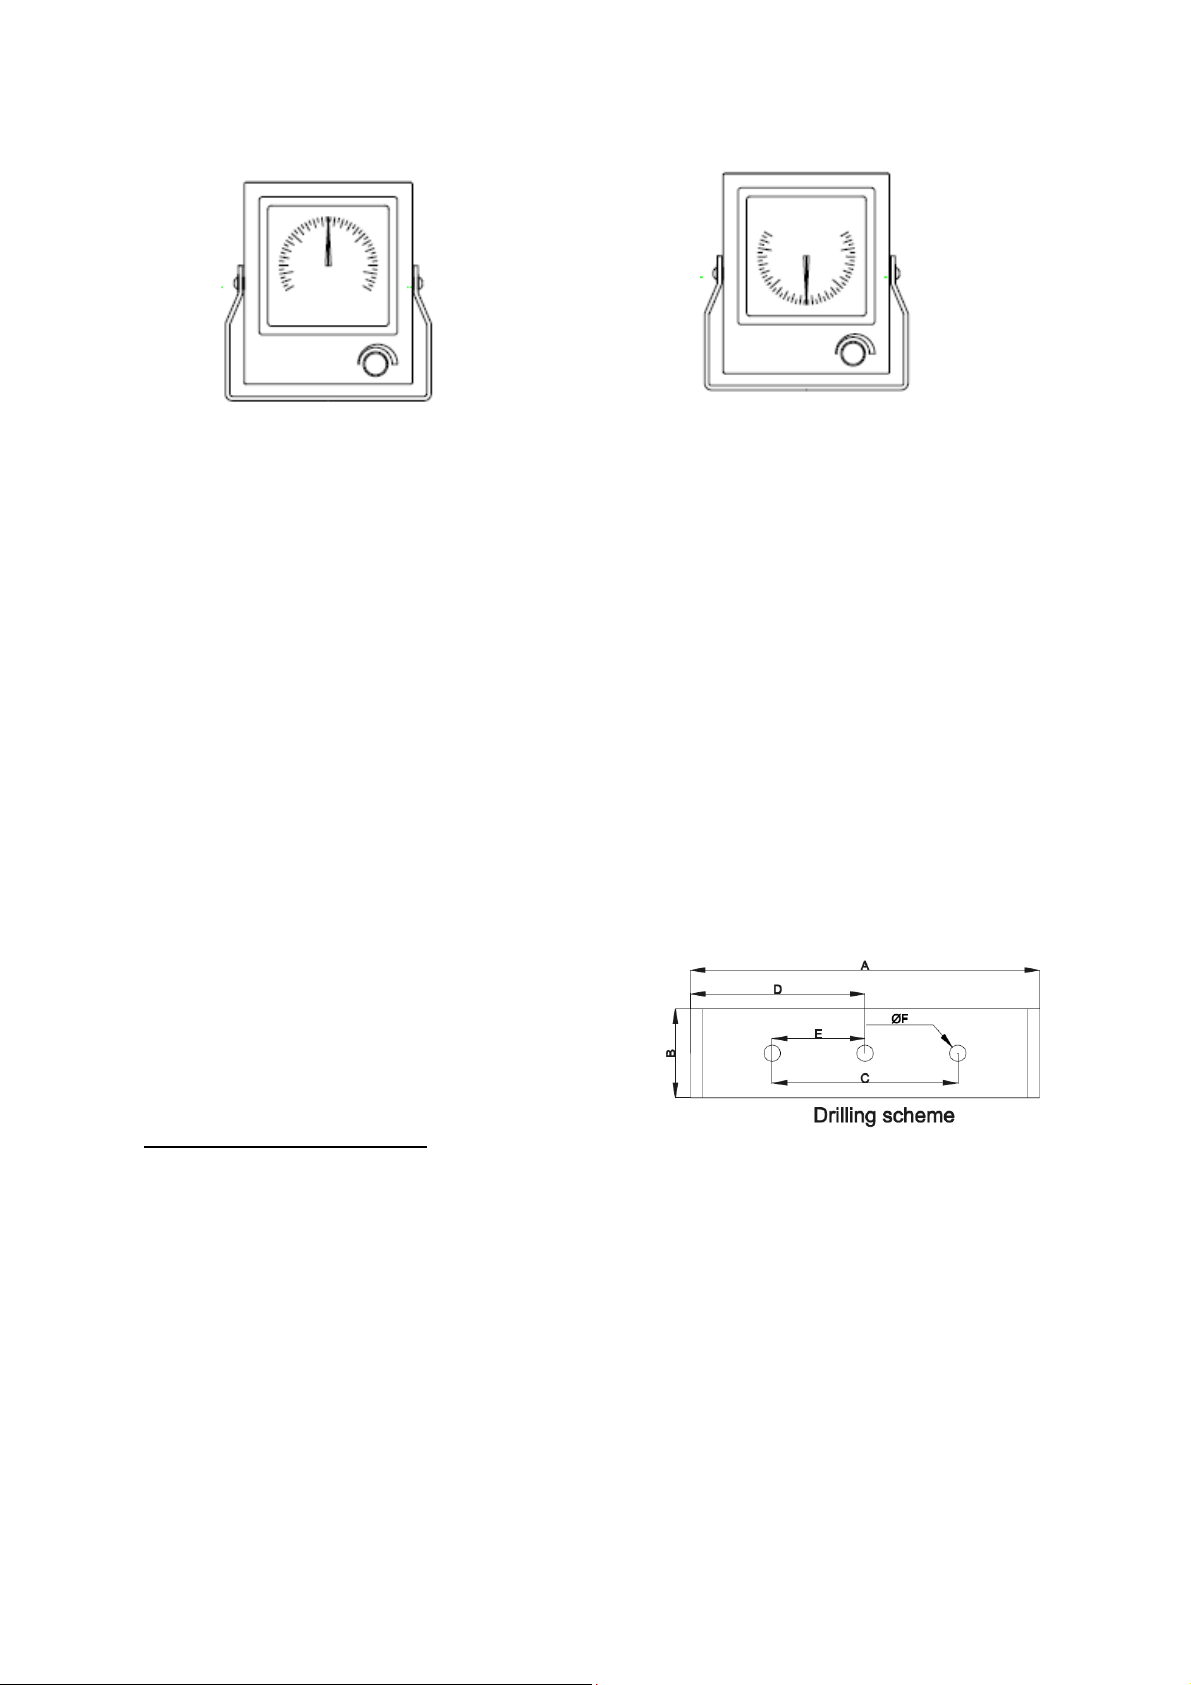
Housing with bracket, built-in dimmer:
Scale 144x144mm:
060327-0000-000 Range ±45°
060328-0000-000 Range ±70°
Scale 192mmx192mm:
060357-0000-000 Range ±45°
060359-0000-000 Range ±70°
Drilling scheme:
Scale: Dimensions (mm)
“A” “B” “C” “D” “E” “F”
144x144 235 60 125 117,5 62,5 11
192x192 284 60 174 142 87 11
060325-0000-000 Range ±45°
060326-0000-000 Range ±70°
060332-0000-000 Range ±45°
060362-0000-000 Range ±70°
PANAMATYPE
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 5
Page 88
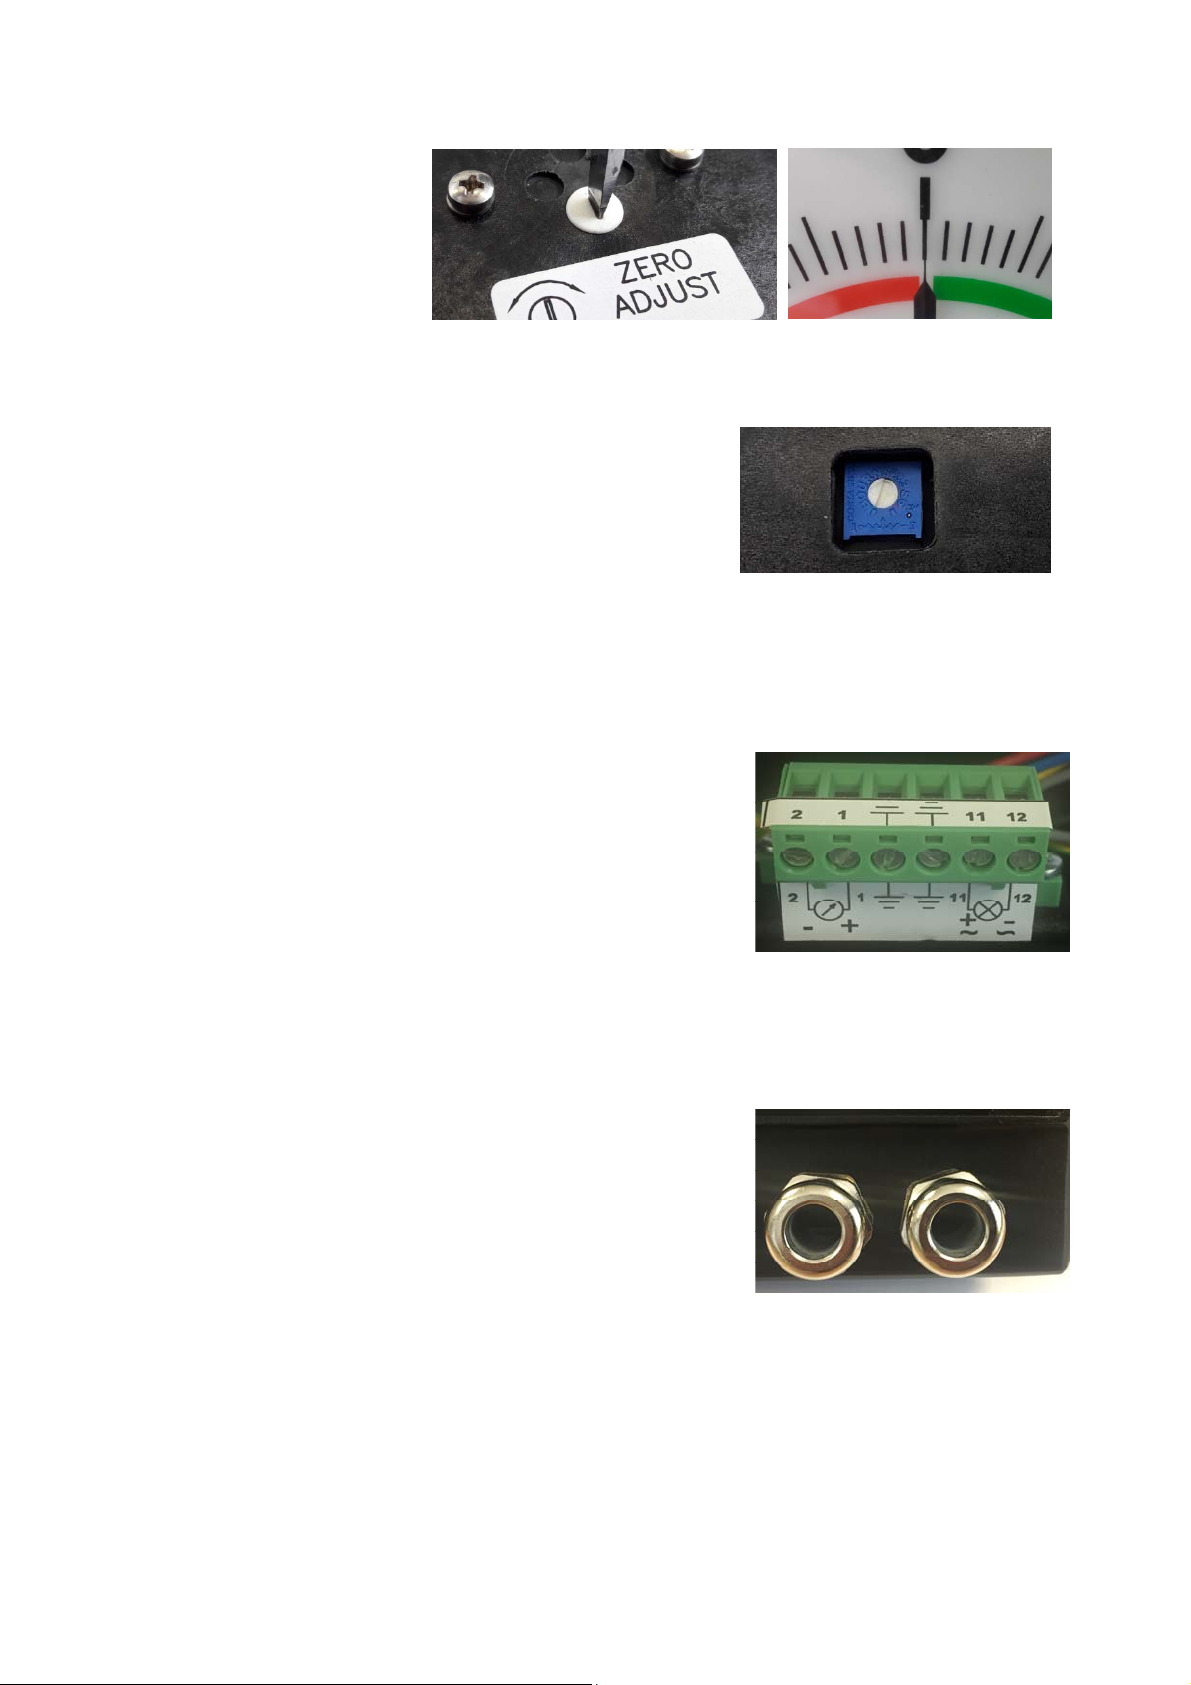
Zero adjustment:
At the back of the indicator is a
small “screw”. Turn gently with a
well-fitting screwdriver to left or
right (max +/-30°) to adjust the
pointer to zero on the scale.
Span adjustment:
At the back of the meter is a small blue potentiometer.
This is intended for the adjustment of the span of the meter.
Apply the signal and turn this pot to set the pointer on the desired
position.
Terminals:
The instrument has six terminals for input
1 = + signal
2 = - signal
11 = illumination
12 = illumination.
2 terminals for earth of the housing
The illumination has no preferred polarity.
The min/max wires sizes are 0,14-2.5 mm
For solid or flexible wire.
2
(26-14 AWG).
Cable glands:
The housing has two Cable glands Pg11
for cable diameter: 5-10mm
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 6
Page 89
Instructions for the exchange of the measuring instrument:
Tools you need: inbus 6mm, socket wrench 5,5mm, small screwdriver
Open the case (4x mm inbus bolt (hex key or Allen key))
BCI without cover
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Page 7
Erstellt: 06/17
Page 90
Disconnect cable (blue -> 2; red -> 1; black -> 11, gray -> 12)
Instrument with disconnected cable
Disconnect the 8x screw which fixing the instrument (8x M3 screw and key)
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 8
Page 91
Remove the instrument from the housing
Check the new instrument ( is the rubber seal present)
Put the new instrument in the housing
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Page 9
Erstellt: 06/17
Page 92
8x screw which fixing the instrument (8x M3 screw and key 5,5mm)
connect cable (blue -> 2; red -> 1; black -> 11, gray -> 12)
close the case (4x mm inbus bolt (hex key or Allen key))
Finished!
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 10
Page 93
Three-face panorama rudder angle indicator:
Scale 144x144mm:
060396-0000-000 Range ±45°
060397-0000-000 Range ±70°
Drilling scheme:
Ø6,5
0
0
4
Ø
8
37
Ø
°
0
2
1
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 11
Page 94
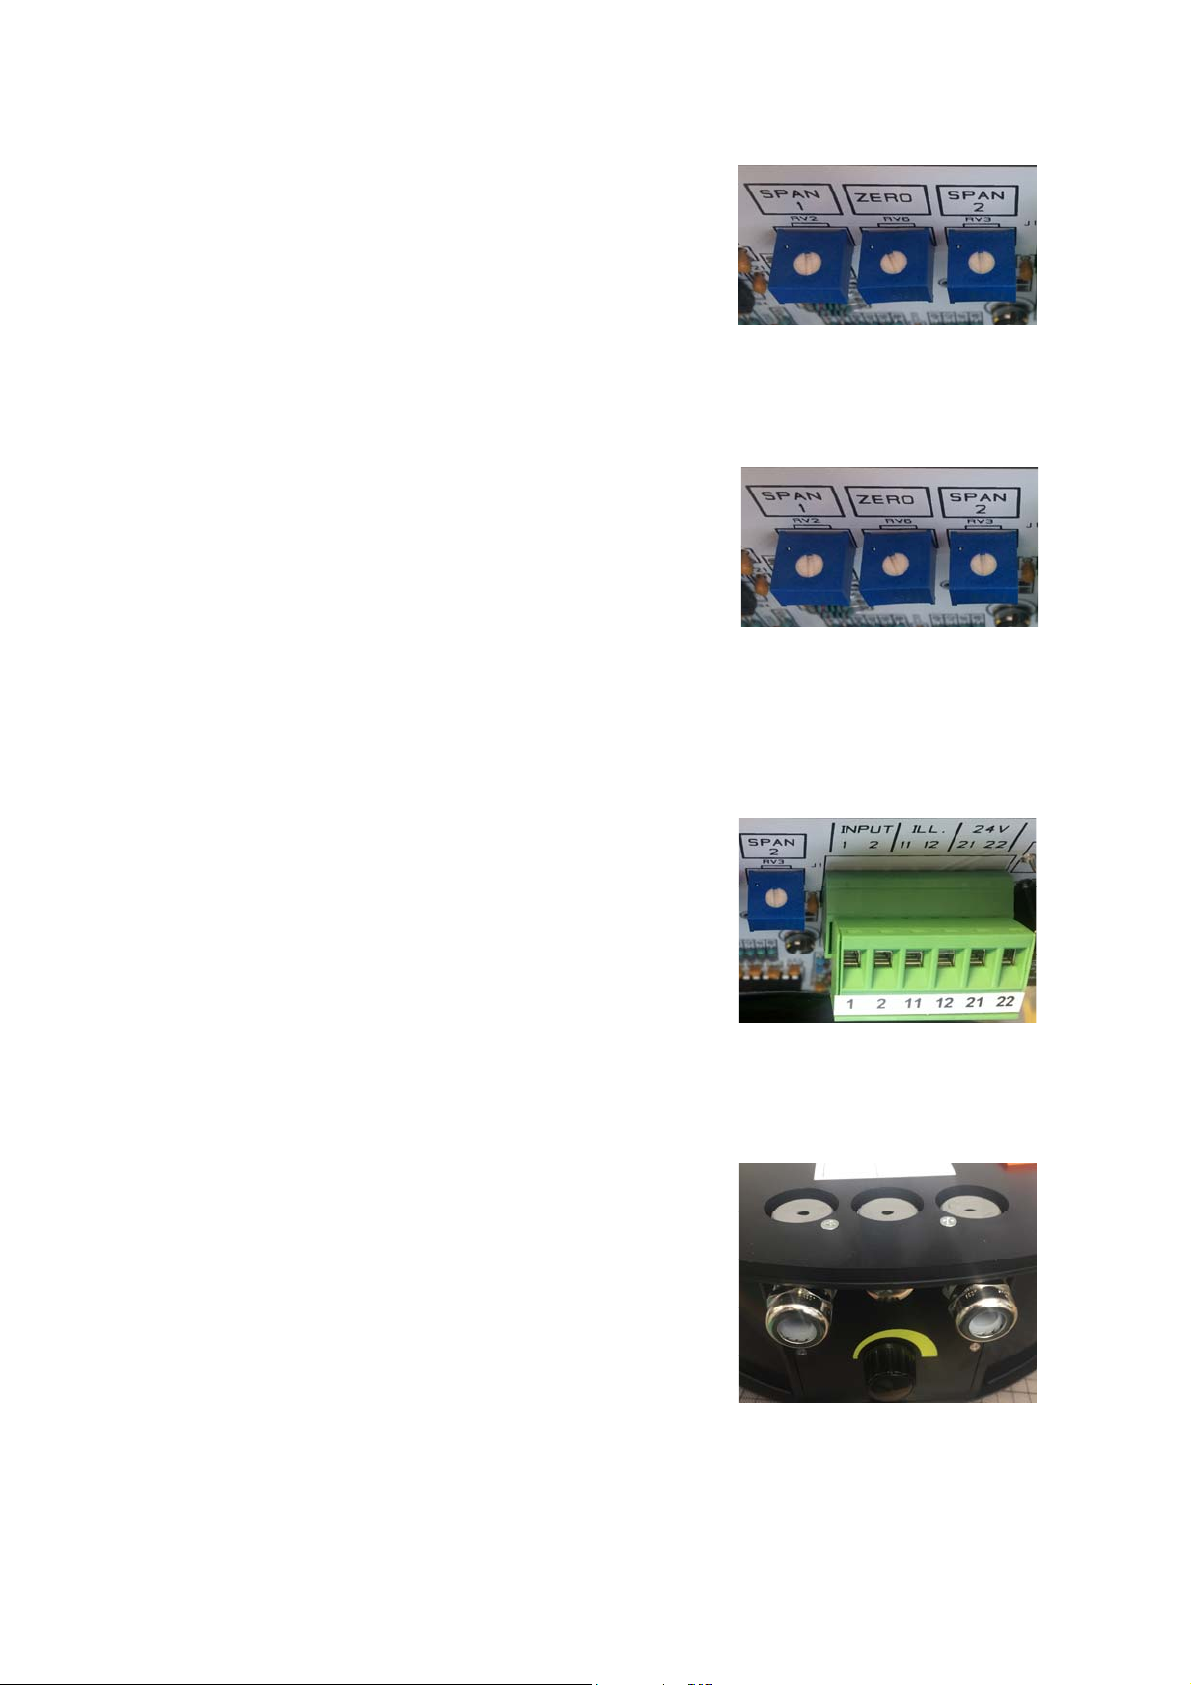
Zero adjustment:
Remove the plate with the dimmer potentiometer
Turn gently with a well-fitting screwdriver the potentiometer “ZERO”
to left or right to adjust the pointer to zero on the scale.
The instrument must be supplied with 24V!
And the input to be set to zero
Span adjustment:
Remove the plate with the dimmer potentiometer
Turn gently with a well-fitting screwdriver the potentiometer
“SPAN1” (for PORT side) or “SPAN2” (for STBD side)
to left or right to adjust the pointer to zero on the scale.
The instrument must be supplied with 24V!
For span adjust PORT side apply full scale input as on label (e.g. -12V)
For span adjust STBD side apply full scale input as on label (e.g. +12V)
Terminals:
The instrument has six terminals for input
1 = + signal
2 = - signal
11 = illumination
12 = illumination.
21 = + supply 24V
22 = - supply 24V.
The illumination has no preferred polarity.
The min/max wires sizes are 0,14-2.5 mm
For solid or flexible wire.
2
(26-14 AWG).
Cable glands:
The housing has two Cable glands Pg11
for cable diameter: 5-10mm
Additional 1 place for a third Pg11
Index:
2017-07-03 installation instructions rudder angle indication systems.docx
Erstellt: 06/17
Page 12
Page 95
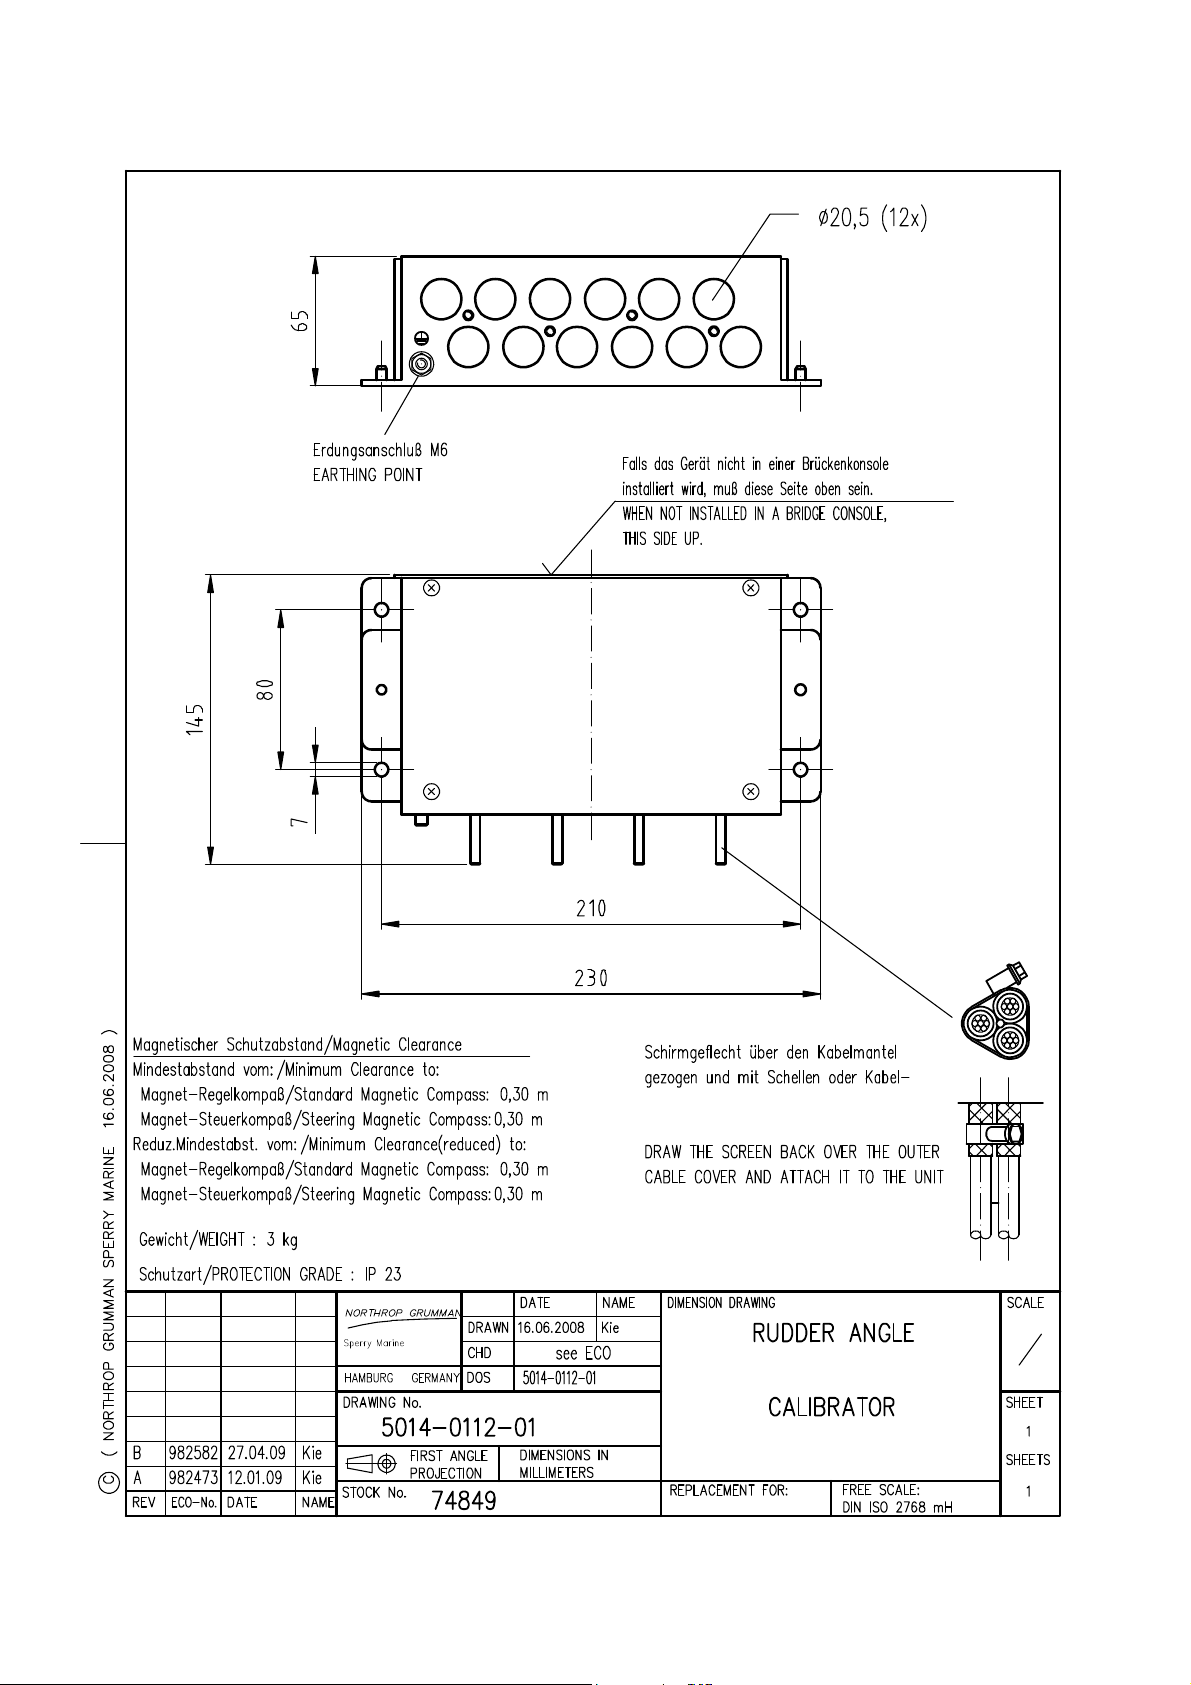
Page 96
Page 97
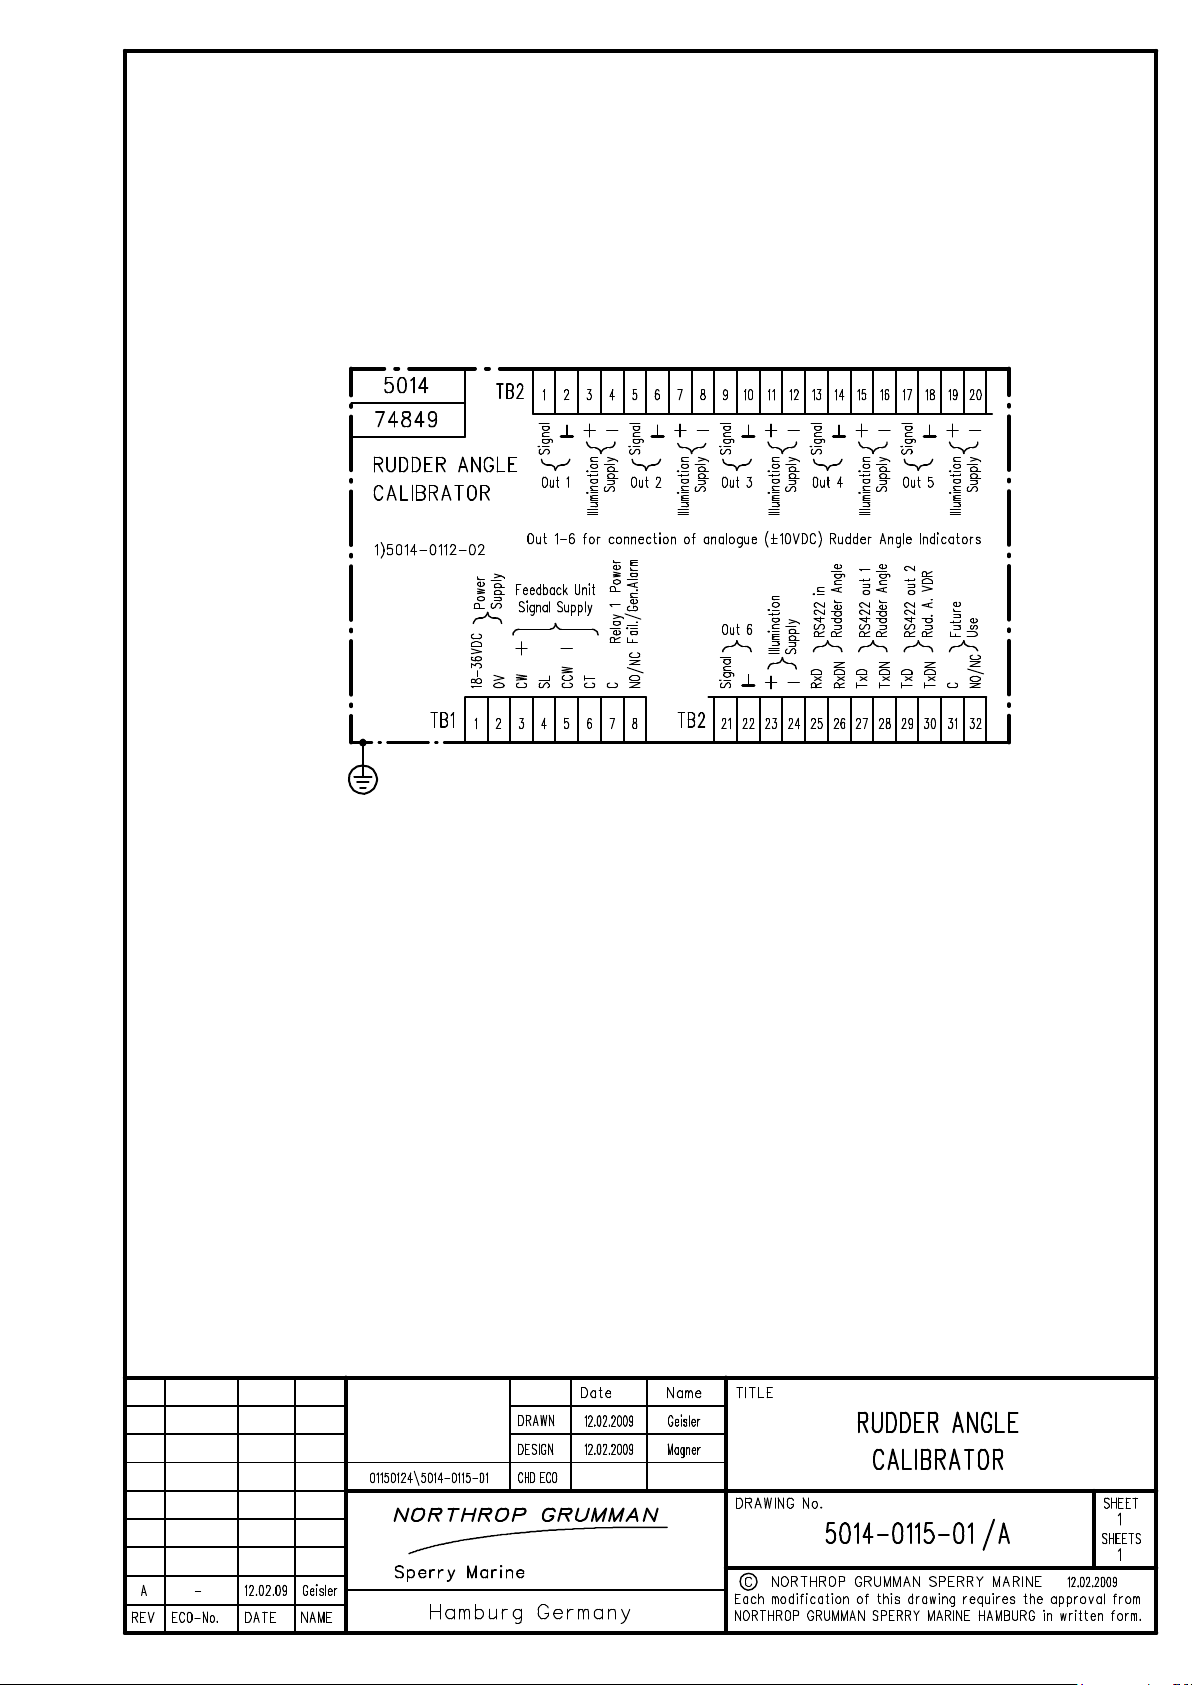
Page 98
Page 99
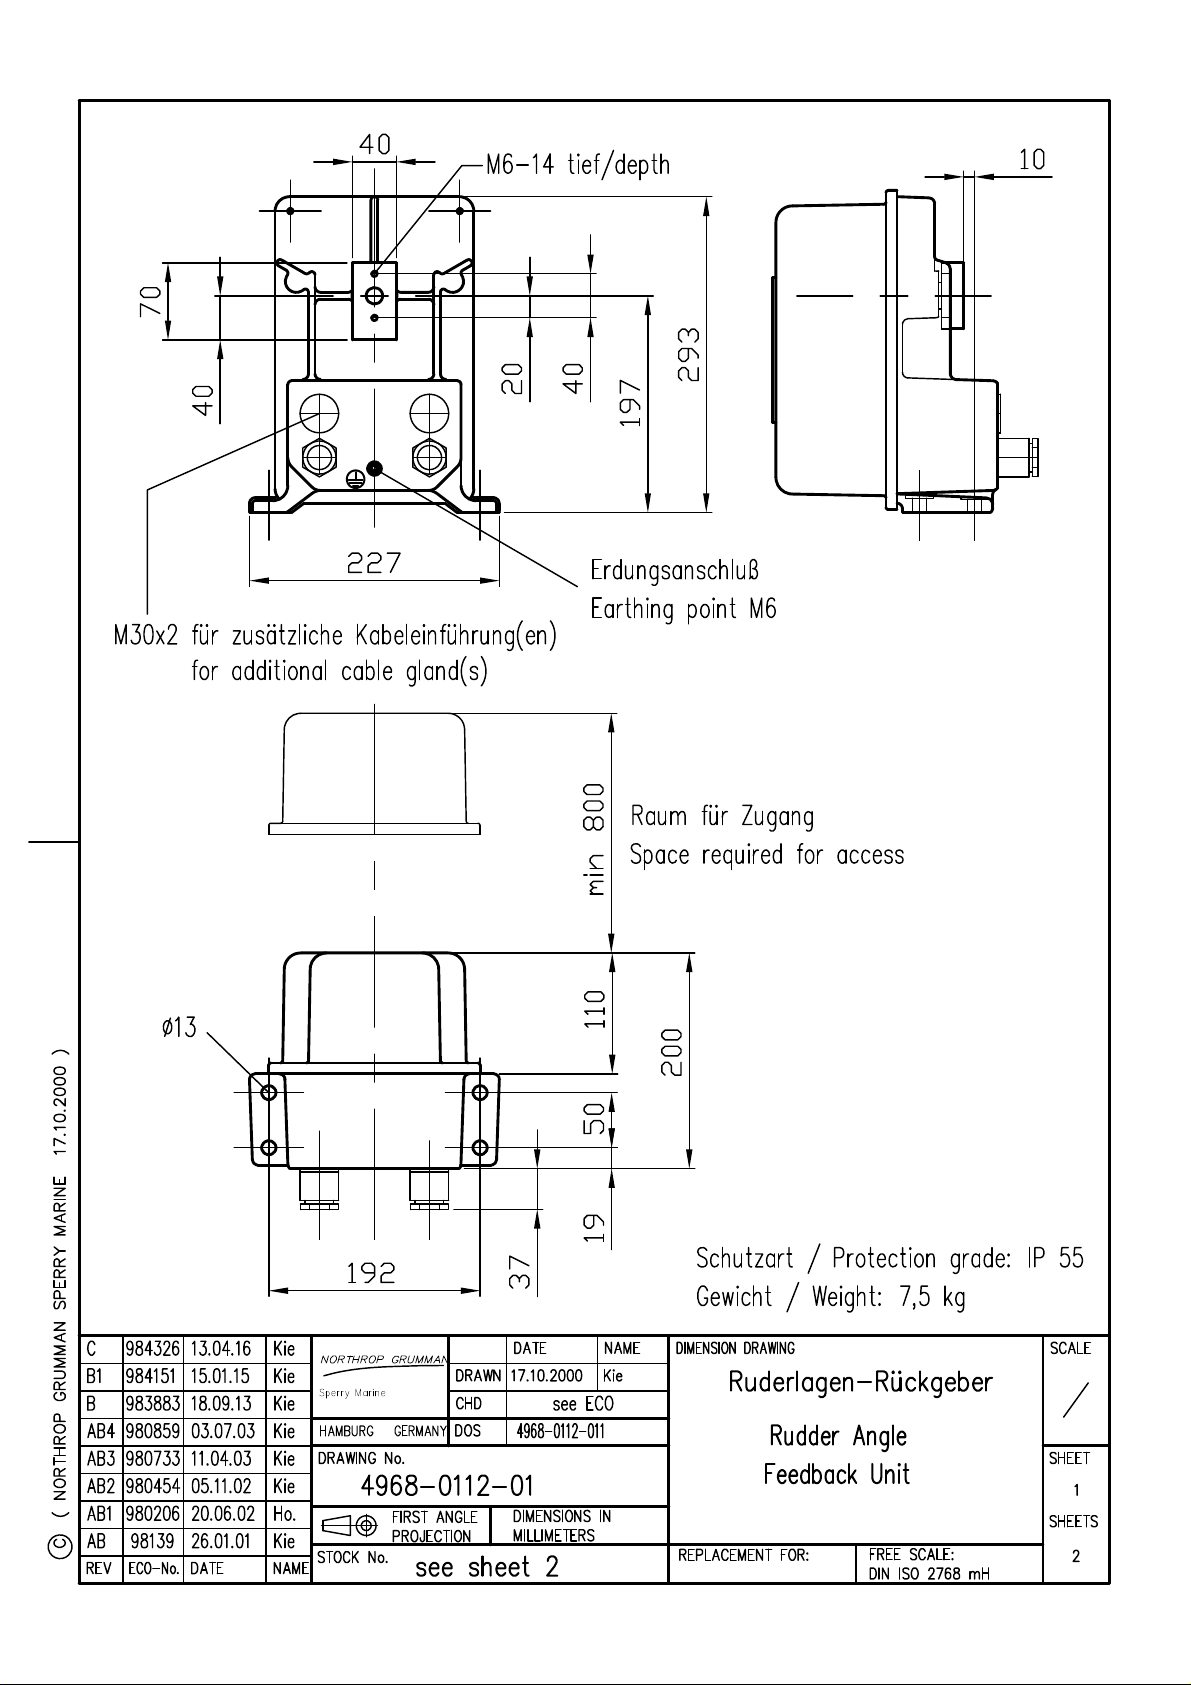
Page 100
 Loading...