

Page 1
Extended U
ser Manual
swinglet CA
M
Revision 12 / September
2014
Copyright © 2010-2014 senseFly Lt
d
Page 2
GENERAL INFORMATION
READ THIS USER MANUAL CAREFULLY BEFORE USING A SENSEFLY LTD PRODUCT.
senseFly Ltd products are intended for professional use only.
Applicable Regulations
senseFly Ltd products are subject to Civil Aviation regulations. Regulations may vary depending on the country
where you intend to operate yourproduct.
ANY USEOF SENSEFLYLTDPRODUCTS IN BREACH OF THE LAW OF THE COUNTRY WHERE YOU OPERATE THE PRODUCT
IS UNDER YOUR SOLE RESPONSIBILITY.
INFORM YOURSELF BEFORE USING THE PRODUCT. SOME COUNTRIES MAY HAVE LAWS THAT LIMIT THE USE OF UNMANNED AIRCRAFT TO ‘LINE-OF-SIGHT’ OPERATIONS AND/OR PROHIBIT THE USE OF UNMANNED AIRCRAFT AT ALL
OR IN SPECIFIC AREAS.
Privacy
Recording and circulating an image of an individual may constitute an infringement of their image and privacy for
which you can be liable. Ask for authorization before taking pictures of an individual, particularly if you want to keep
your recordings and/or circulate images on the Web or any other medium. Do not circulate degrading images or
ones that could undermine the reputation or dignity of an individual. Check that your use of the cameras on board
senseFly Ltd products comply with the legal provision on privacy in the country where you operate your product.
Limited Warranty
SenseFly Ltd warrants that the product will be free from defects in material and workmanship for a period of twelve
(12) months from the date of delivery. SenseFly Ltd further warrants that the product will perform substantially in
accordance with its specification. During the warranty period senseFly Ltd’s sole liability shall be at senseFly Ltd’s
sole option, either to repair or to replace the defective product with another product or a product with similar specifications, at no charge, or to reimburse the purchase price of the product, or if repair or replacement is not possible,
issue a credit note; provided however, that the defect has been confirmed by senseFly Ltd and that the defective
product is returned to senseFly Ltd in accordance with the support and repair form together with all required flight
logfiles.
Warranty does not apply, without limitation, in case: a) the products are not stored and used according to their
specifications, b) the products are damaged due to carelessness, negligence, or wrong use by the user, and c) for
defects due to normal wear and tear including, but not limited to, deterioration to the airframe after first flight,
normal degradation, misuse, moisture or liquids, proximity or exposure to heat, accidents, excessive strain, abuse,
neglect, misapplication,repairs ormodifications made by thirdparty other thansenseFly Ltd,damage dueto manual
operation, damage due to take-off orlanding locationwith obstacles,damage dueto lowaltitude flight, damage due
to loss of data radio connection, damage due to strong wind, rain or humidity, or other causes for which senseFly Ltd
has no control.
Page 3
THE FOREGOING WARRANTIES ARE IN LIEU OF ALL WARRANTIES, EITHER EXPRESSED OR IMPLIED, INCLUDING WITHOUT LIMITATION ANY IMPLIED WARRANTY OF MERCHANTABILITY OR FITNESS FOR A PARTICULAR PURPOSE, AND OF
ANY OTHER OBLIGATION ON THE PART OF SENSEFLY LTD.
Limitation of liability
TO THE EXTENT PERMITTED BY APPLICABLE LAW,IN NO EVENT WILL SENSEFLY LTD BE LIABLE FOR ANY LOSSOF REVENUE, LOSS OF PROFIT, LOSS OF DATA, OR INDIRECT, SPECIAL, INCIDENTAL OR CONSEQUENTIAL DAMAGES, EVEN IF
SENSEFLY LTD HAS BEEN NOTIFIED OF THE POSSIBILITY OF SUCH DAMAGES, AND WHETHER THIS LIABILITY ARISES
FROM A CLAIM BASED ON CONTRACT, WARRANTY, TORT OR OTHERWISE, WITH THE EXCEPTION OF GROSS NEGLIGENCE AND DEATH.
YOU SHALL AT ALL TIMES OPERATE THE PRODUCT IN AREAS OR UNDER CIRCUMSTANCES SO AS TO GUARANTY SECURITY AND SAFETY OF PEOPLE, PROPERTY AND ANIMALS.
Copyrights
senseFly Ltd reserves the right to make changes to specifications and product descriptions contained in this document at any time without notice. Please consult www.sensefly.com for the latest release.
Copyright © 2014 senseFly Ltd. Allrights reserved. REPRODUCTION, USE OR DISCLOSUREOF ALL OR IN PARTOF THIS
MANUAL TO THIRD PARTIES WITHOUT THE PRIOR WRITTEN PERMISSION OF SENSEFLY LTD IS STRICTLY PROHIBITED.
Page 4
Address
senseFly Ltd
Route de Gen`eve 38
1033 Cheseaux-Lausanne
Switzerland
Website: http://www.sensefly.com
Technical support
If you have questions on your swinglet CAM or accompanying software please consult senseFly Ltd’s
Technical support website at the following address:
http://www.sensefly.com/support/
Page 5
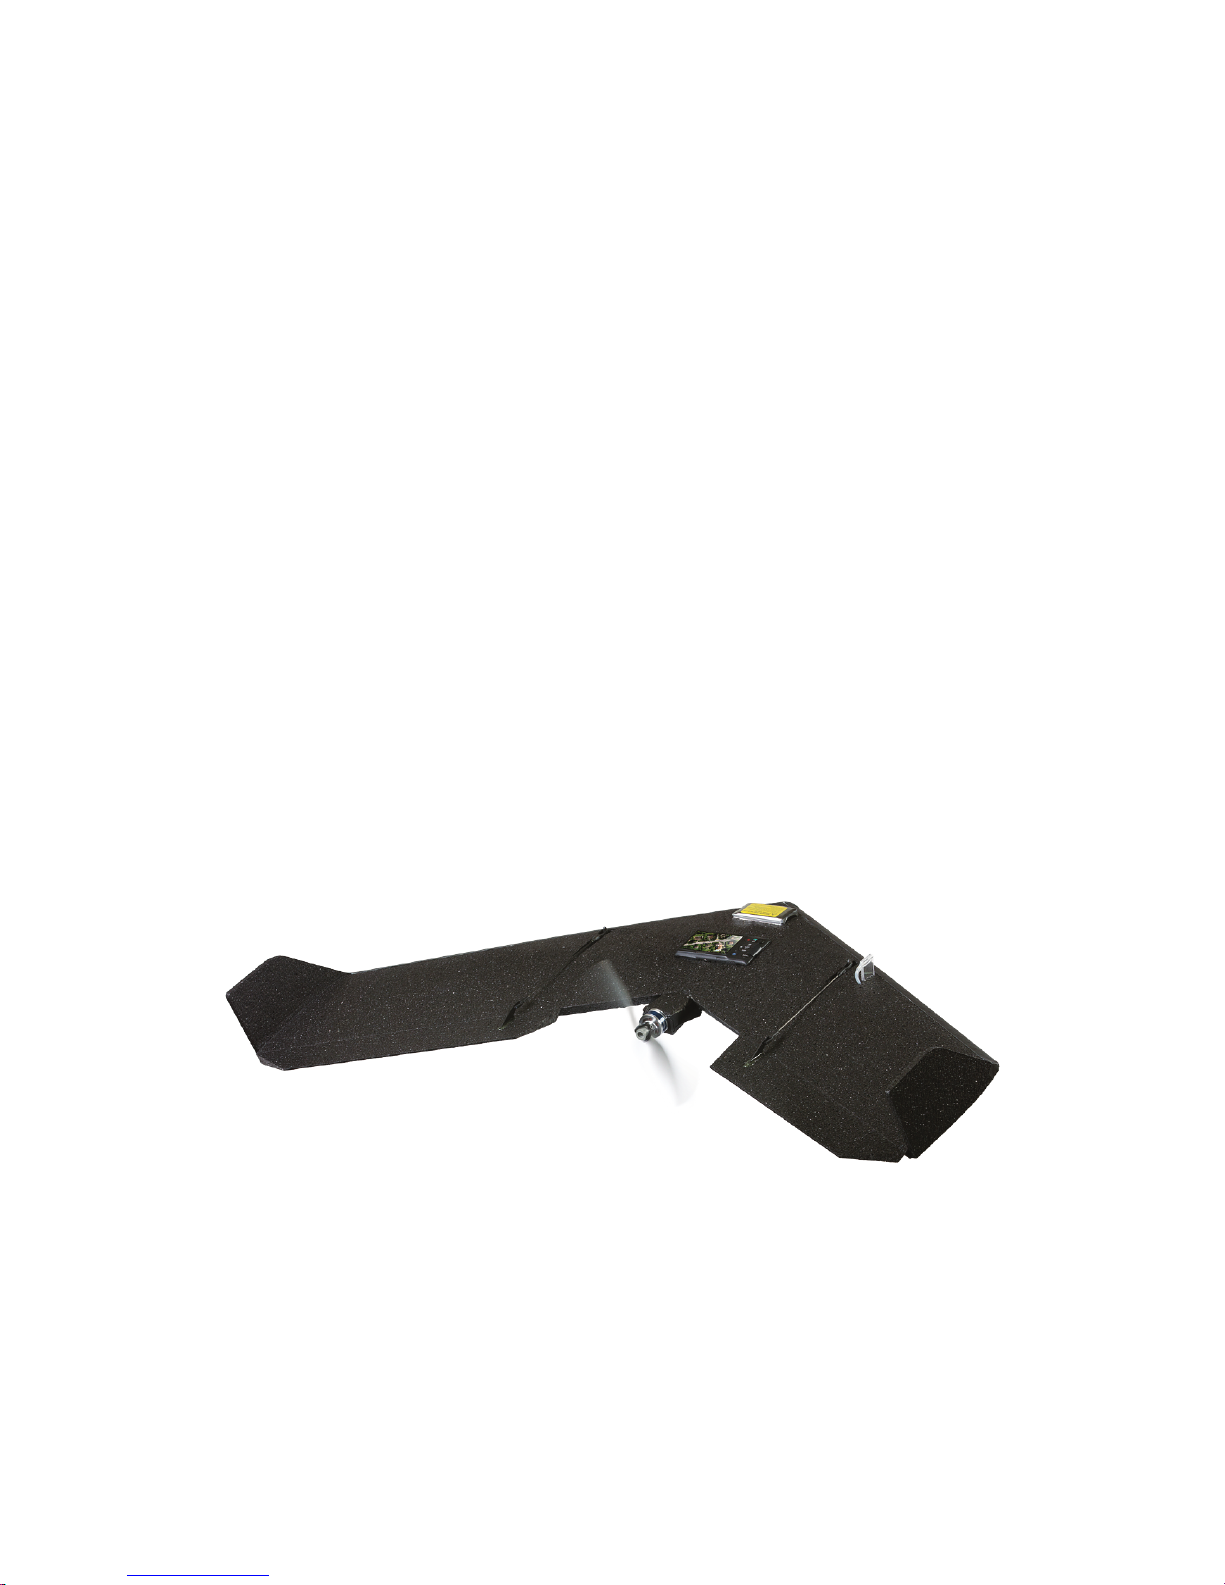
Welcome to your swinglet CAM
Congratulations on your purchase of the swinglet CAM, a complex and powerful
yet intuitive autonomous mapping system. We take great care to develop and
design the best possible hardware and software tools for quick, high-quality and
easy-to-use 2D and 3D aerial mapping.
Page 6
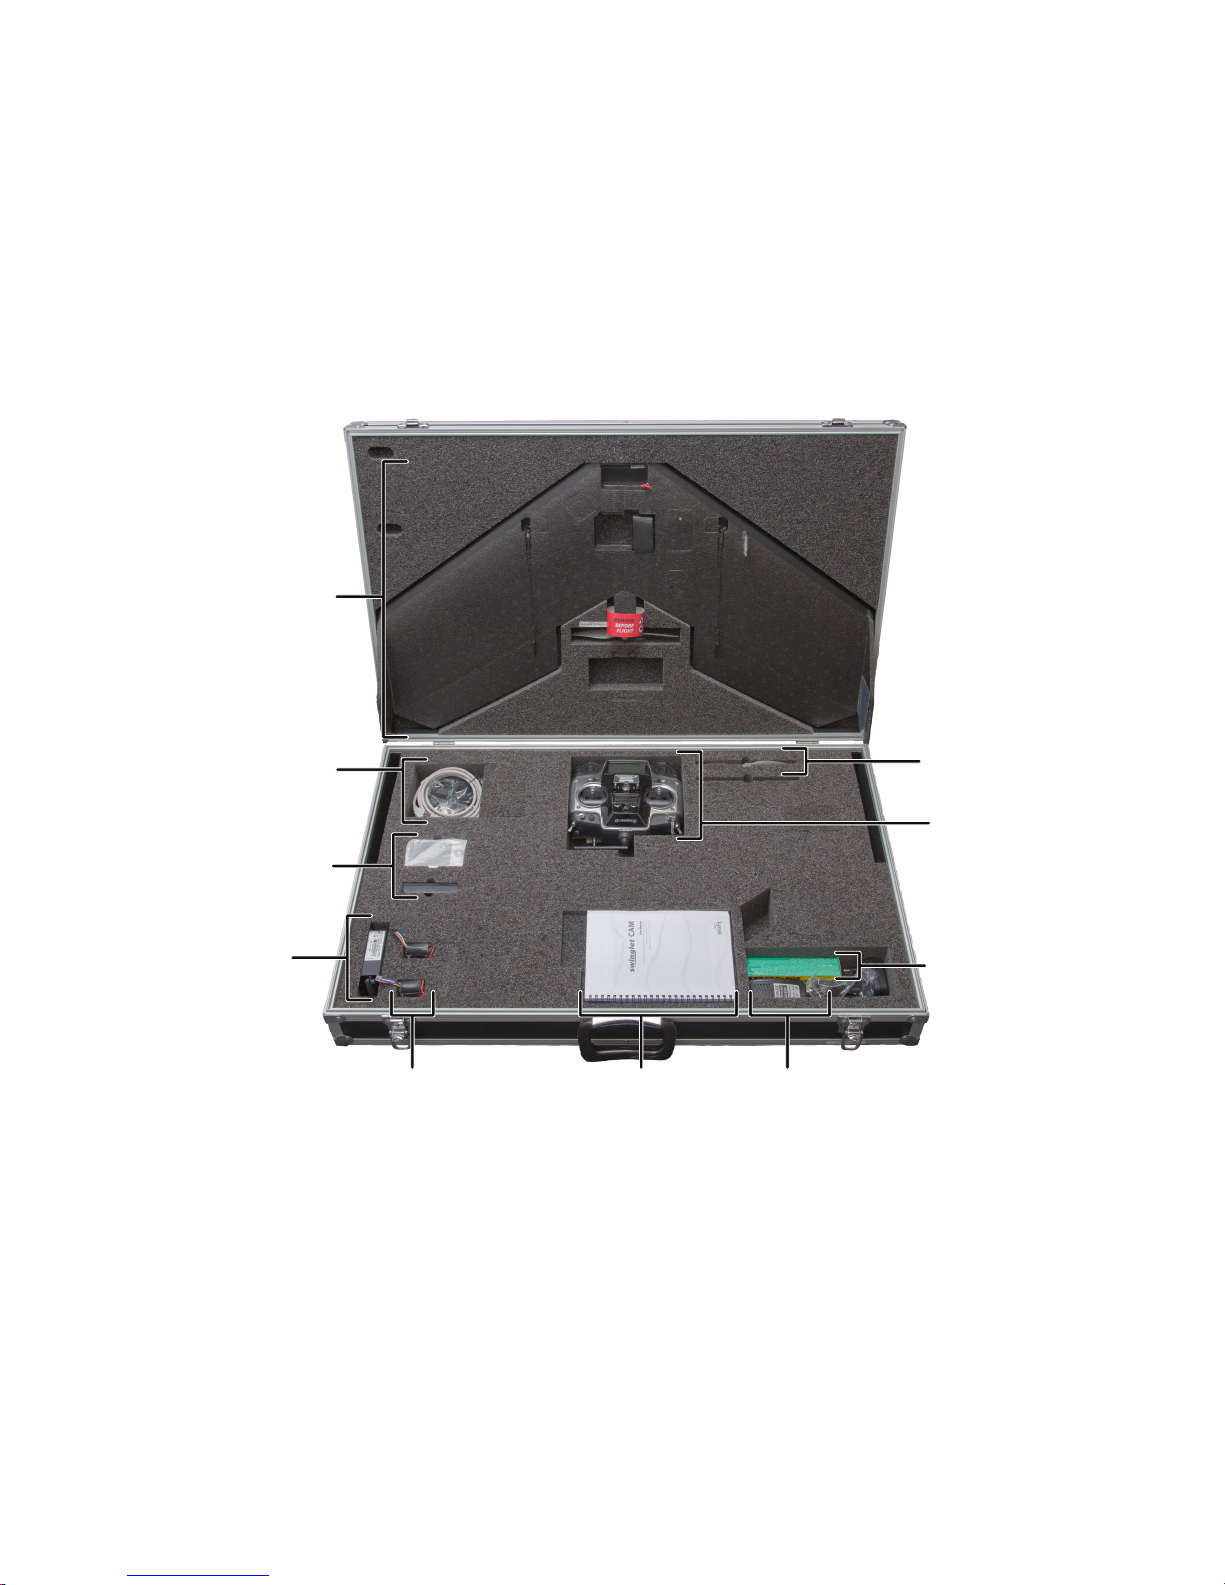
Package contents
swinglet CAM
airframe
spare
propeller
remote
control
camera with
charger
User manualbattery packs
ground
modem
battery and remote chargers
EPP glue
cables and
propeller
attachment
bands
Page 7
The standard swinglet CAM package contains the following items:
• 1x carrying case with foam protection
• 1x swinglet CAM airframe with built-in autopilot
• 1x spare propeller
• 10x spare propeller attachment rubber bands
• 2x Lithium-Polymer battery packs
• 1x Lithium-Polymer battery charger (including cables)
• 1x 2.4 GHz USB ground modem for radio data link (including USB cable)
• 1x 2.4 GHz remote control (including battery pack, charger and cables)
• 1x USB cable for interfacing with camera and on-board autopilot
• 1x EPP glue
• 1x swinglet CAM User Manual
Depending on your order, your package may also include other items, such as
additional payloads. Please verify upon delivery that your package is complete.
In case of a missing item, please contact your swinglet CAM reseller immediately.
Page 8
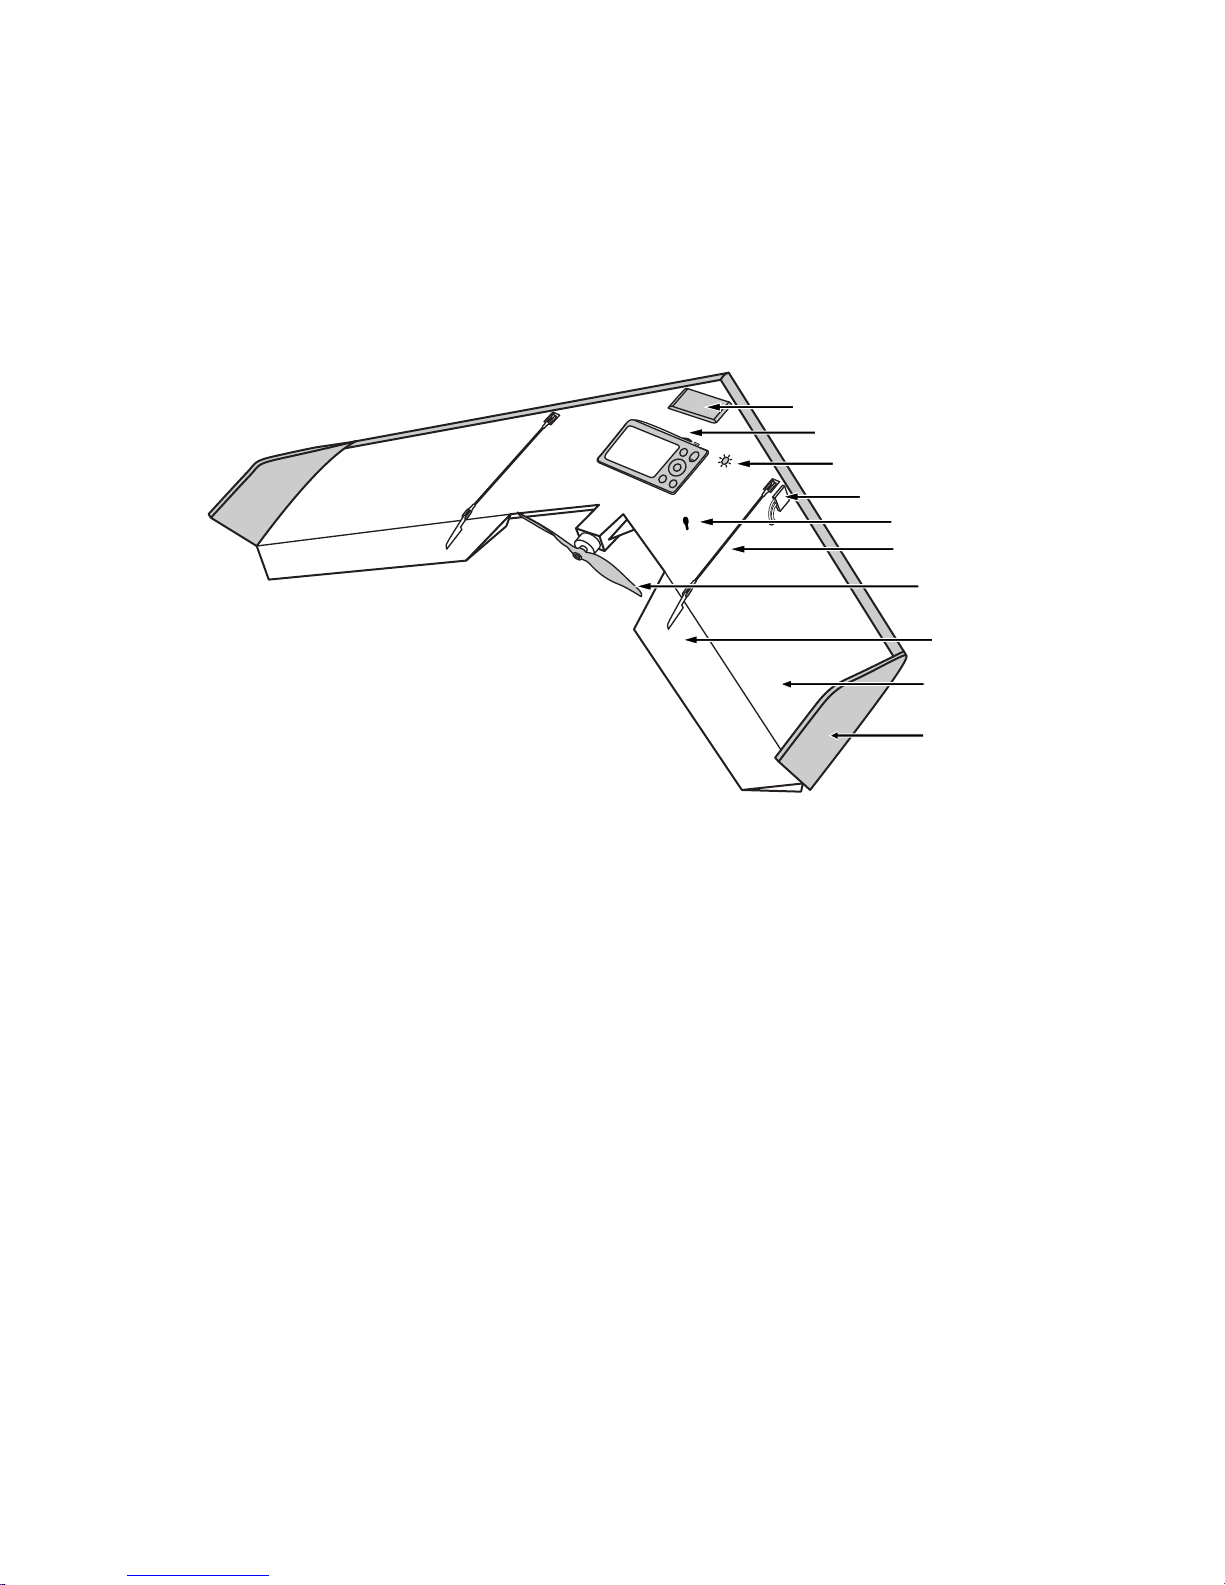
Hardware features
ailerons
winglets
propeller
servo rods
status LED
pitot probe
battery
airframe
camera
Top face of the swinglet CAM
antenna
The swinglet CAM is anautonomous flying drone comprised of the following components:
• Airframe: This is the main structure of the drone, made of durable EPP
(Expanded Polypropylene).
• Winglets: These structures add aerodynamic stability to thedrone while it
is in flight.
• Ailerons: Used to control the swinglet CAM while in flight.
• Servo rods: Actuate the ailerons using the servo-motors within the frame
of the swinglet CAM.
• Propeller: Used to generate thrust while it is in flight.
Page 9
Caution: When attached to the motor the propeller spins at high
speeds and can be potentially dangerous if itcomes into contact with
exposed skin. Be sure to alwayskeepyourhands clear of the propeller
when the battery is attached to the swinglet CAM.
• Battery: The swinglet CAM is powered by a LiPo (Lithium Polymer) battery.
Caution: Proper care of your battery is essential. Please read section
‘Proper battery care’ on page123 before using your drone for thefirst
time.
• Camera: The swinglet CAM features a built-in camera for taking aerial im-
ages.
• Data Link Antenna: Used by the drone to communicate with the eMotion
software through the USB ground modem.
• Pitot probe: Thisis thesensor used by the swinglet CAM to detect airspeed,
wind and altitude. It must be kept clean and clear of obstructions to function properly.
• Status LED:This coloured LED displaysthecurrent state of the swingletCAM.
Page 10
Software features
The swinglet CAM package allowsfor thedownloadand use of eMotion *and Postflight Terra LT * at no extra cost.
eMotion is the integrated software package that allows you to interact with your
swinglet CAM. Its easy-to-use interface allows you to plan a mapping flight intu-
itively from the comfort of your office or directly in the field. Once the drone is
launched, you can use eMotion’s wireless connection with your swinglet CAM to
track its position, monitor the progress of your mapping flight and send commands if desired.
Once your swinglet CAM returnsafter an aerial mappingflight it is the turnof Post-
flight Terra LT to process the captured images fully automatically. While you are
still in the field Postflight Terra LT analyses the quality of the captured images and
generates an easy to understand report, letting you know immediately if thedata
you captured meets your mapping requirements.
∗ Software access terms and conditions apply.
Page 11
Contents
I Quick start guide 15
1 Planning and simulating a flight 16
1.1 Installing eMotion, PostflightTerraLT, and the groundmodemdrivers 16
1.2 The eMotion interface . . . . . . . . . . . . . . . . . . . . . . . 17
1.3 Creating a new flight plan . . . . . . . . . . . . . . . . . . . . . 19
1.4 The mission phase of a flight . . . . . . . . . . . . . . . . . . . . 20
1.5 Simulating your flight . . . . . . . . . . . . . . . . . . . . . . . 22
1.6 Getting ready for a mission . . . . . . . . . . . . . . . . . . . . 23
2 Executing a flight 25
2.1 Weather check . . . . . . . . . . . . . . . . . . . . . . . . . . . 25
2.2 Preparing the swinglet CAM for flight . . . . . . . . . . . . . . . 26
2.3 The setup phase of a flight . . . . . . . . . . . . . . . . . . . . . 33
2.4 Take-off . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 35
2.5 In-flight monitoring and control . . . . . . . . . . . . . . . . . . 39
2.6 Landing . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 41
2.7 Potential in-flight errors . . . . . . . . . . . . . . . . . . . . . . 41
3 Processing image data 43
3.1 Importing images and flight data . . . . . . . . . . . . . . . . . 43
3.2 In-field image quality check . . . . . . . . . . . . . . . . . . . . 46
Page 12
II Advanced functionalities 49
4 Understanding aerial mapping with the swinglet CAM 50
4.1 Waypoints and their properties . . . . . . . . . . . . . . . . . . 50
4.2 Advanced polygonal mission area . . . . . . . . . . . . . . . . . 55
4.3 3D mission planning using elevation data . . . . . . . . . . . . . 56
4.4 Flight visualization in Google Earth
TM
. . . . . . . . . . . . . . . 58
4.5 Autonomous controller and modes of flight . . . . . . . . . . . . 60
4.6 Flying multiple drones at the same time . . . . . . . . . . . . . 63
4.7 Individual photo targets and oblique imagery . . . . . . . . . . 68
5 eMotion in-depth guide 70
5.1 Toolbar . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 71
5.2 Simulator . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 74
5.3 Control Bar . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 76
5.4 Flight Monitoring tab . . . . . . . . . . . . . . . . . . . . . . . 79
5.5 Setup Phase tab . . . . . . . . . . . . . . . . . . . . . . . . . . 82
5.6 Mission Planning tab . . . . . . . . . . . . . . . . . . . . . . . . 86
5.7 Mission Waypoints tab . . . . . . . . . . . . . . . . . . . . . . . 95
5.8 Camera tab . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 97
5.9 Flight Parameters tab . . . . . . . . . . . . . . . . . . . . . . . 102
6 Manual control of the swinglet CAM 106
6.1 Enabling manual control . . . . . . . . . . . . . . . . . . . . . . 106
6.2 Pre-flight testing of the remote control . . . . . . . . . . . . . . 108
6.3 Full Manual mode . . . . . . . . . . . . . . . . . . . . . . . . . 109
6.4 Assisted Manual mode . . . . . . . . . . . . . . . . . . . . . . . 110
Page 13
6.5 Charging the remote control . . . . . . . . . . . . . . . . . . . . 112
Page 14
III Maintenance, Repair and Troubleshooting 115
7 Maintenance and repair of the swinglet CAM 116
7.1 Updating the swinglet CAM software . . . . . . . . . . . . . . . 116
7.2 Cleaning and storage . . . . . . . . . . . . . . . . . . . . . . . . 119
7.3 Full airframe and sensor inspection . . . . . . . . . . . . . . . . 119
7.4 Repairing the swinglet CAM airframe . . . . . . . . . . . . . . . 123
7.5 Proper battery care . . . . . . . . . . . . . . . . . . . . . . . . . 123
8 Troubleshooting 126
8.1 Pre-flight errors . . . . . . . . . . . . . . . . . . . . . . . . . . . 127
8.2 Take-off vetoes . . . . . . . . . . . . . . . . . . . . . . . . . . . 130
8.3 In-flight warnings . . . . . . . . . . . . . . . . . . . . . . . . . 131
8.4 Critical failures . . . . . . . . . . . . . . . . . . . . . . . . . . . 141
8.5 Resetting default camera settings . . . . . . . . . . . . . . . . . 144
8.6 Improving radio signal communication . . . . . . . . . . . . . . 145
8.7 Losing and locating your swinglet CAM in the field . . . . . . . . 146
8.8 Reporting a problem with your swinglet CAM . . . . . . . . . . . 147
IV Specifications 149
1 Software requirements 150
2 Drone specifications 151
Page 15
Part I
Quick start guide
The first part of this document introduces you to the swinglet CAM and contains
the basic information you will need to plan and execute a simple mapping project.
A typical mapping project can be divided into three main phases:
1. Planning and simulating a flight: Every project beginswith careful planning, whether it is a quick flight over a small area or a multi-stage flight
in complex terrain. Section ‘Planning and simulating a flight’ on the next
page describes how to use the Mission Planning featuretoquickly generate
a flight plan and to test it using the built-in simulator.
2. Executing a flight: Once planning is complete, it is time for the drone to
perform its flight. In section ‘Executing a flight’ on page 25 you will learn
how to prepare your drone for flight, connect it to eMotion, and to monitor
it in flight while it gathers images. Though the swinglet CAM can complete
a flight fully autonomously from take-off to landing, you can also modify
its flight plan at any point during flight.
3. Processing image data: The last step in a project is converting the images taken by your swinglet CAM into usable products such as precise georeferenced orthomosaics or 3D terrain models. section ‘Processing image
data’ on page 43 leads youthrough the process of transferring images from
the drone to a computer, checking if the image quality suits your needs
while still in the field and producing advanced 2D and 3D maps.
Page 16
Quick start guide
1 Planning and simulating a flight
Goal of this section: This section introduces the eMotion software
used to interface with the swinglet CAM. It describes the steps required to plan, simulate, and save a simple mapping flight. A more
detailed description of eMotion and its advanced functions is presented in section ‘eMotion in-depth guide’ on page 70.
1.1 Installing eMotion, Postflight Terra LT, and theground mo-
dem drivers
You can download the latest version of eMotion and Postflight Terra LT at:
www.sensefly.com/support/download
Use the password provided with your swinglet CAM to access the download section.
We recommend that you download and install Google EarthTMto take full advantage of the features of eMotion. You can find more information at the following
address:
www.google.com/earth/
To install eMotion on Windows, simply execute the provided installers for eMo-
tion and Postflight Terra LT and follow the on-screen instructions. The eMotion
and Postflight Terra LT software will be available in the ‘Start’ menu. Drivers for
the USB groundstation ground modem will automatically be installed along with
eMotion.
In case a problem arises after connecting the ground modem to the computer for
the first time you can find the drivers in one of the following directories (depending on your version of Windows):
16
Page 17
Planning and simulating a flight
C:\Program Files\senseFly\eMotion 2\usb driver\
C:\Program Files (x86)\senseFly\eMotion 2\usb driver\
See section ‘Updating the swinglet CAM software’ on page 116 if you have any
difficulty with software installation.
1.2 The
eMotion
interface
Thanks to the powerful tools available within eMotion, designinga mappingflight
for your swinglet CAM is a simple process. To get started, launch eMotion and
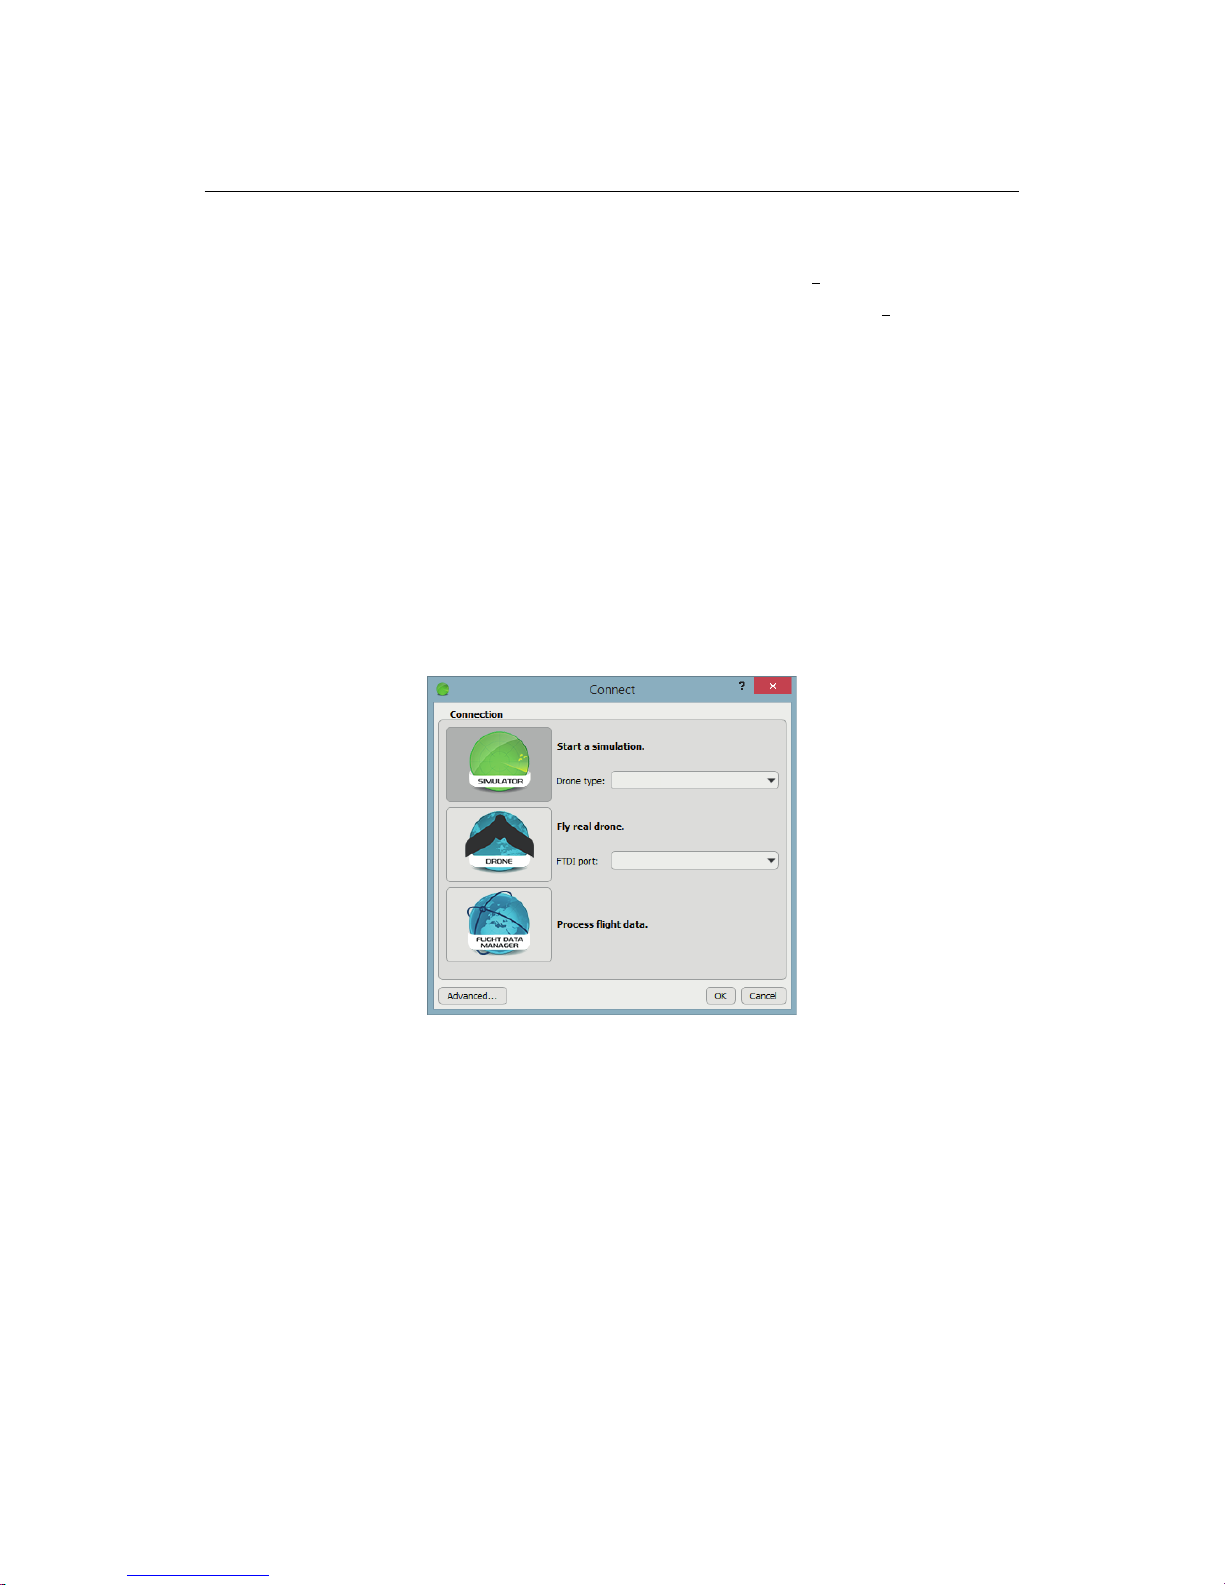
choose what you would like to do...
• To run a simulation, select the simulator, choose the drone you want to
simulate and click OK.
• To fly a drone, connect your ground modem to your computer and select
Drone. Ifyouhavemore than one USB device connected to your PC , choose
the ground modem you want to connect to from the list and click OK. Otherwise, just click OK.
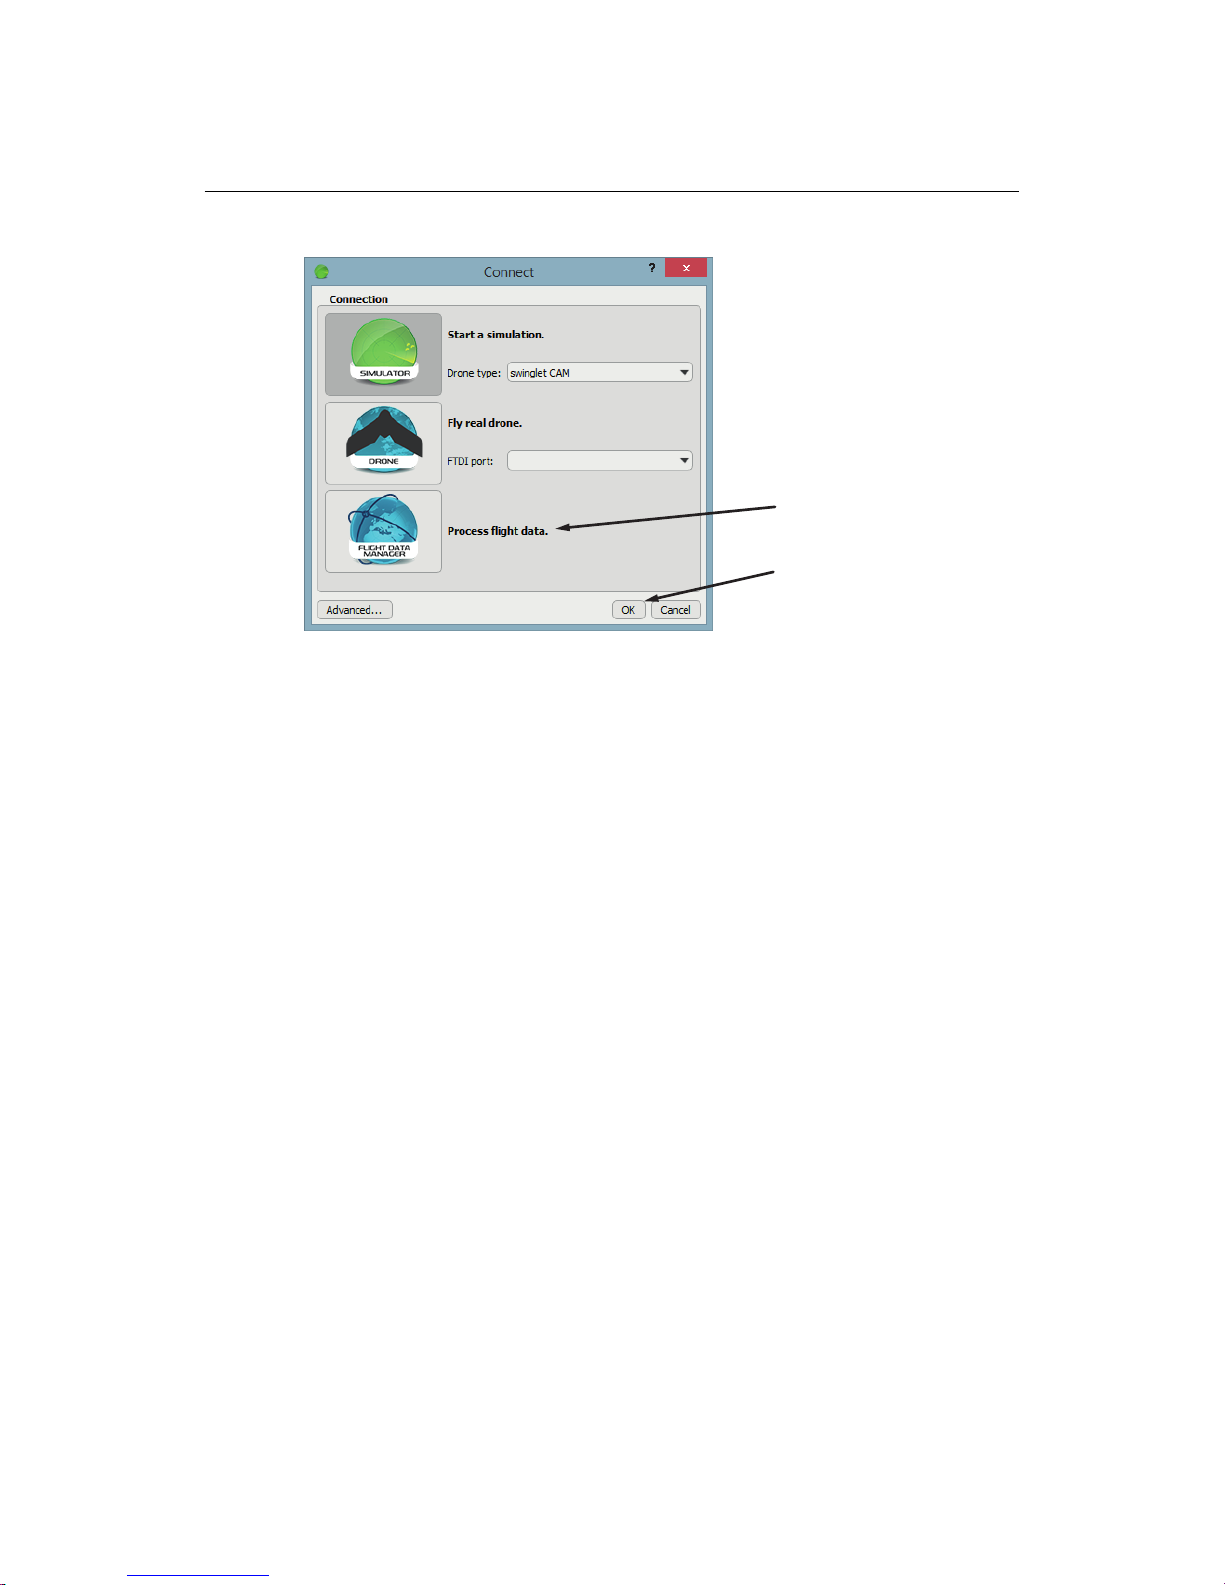
• To process flight data you already created, select the Flight Data Manager
and click OK.
17
Page 18
Quick start guide
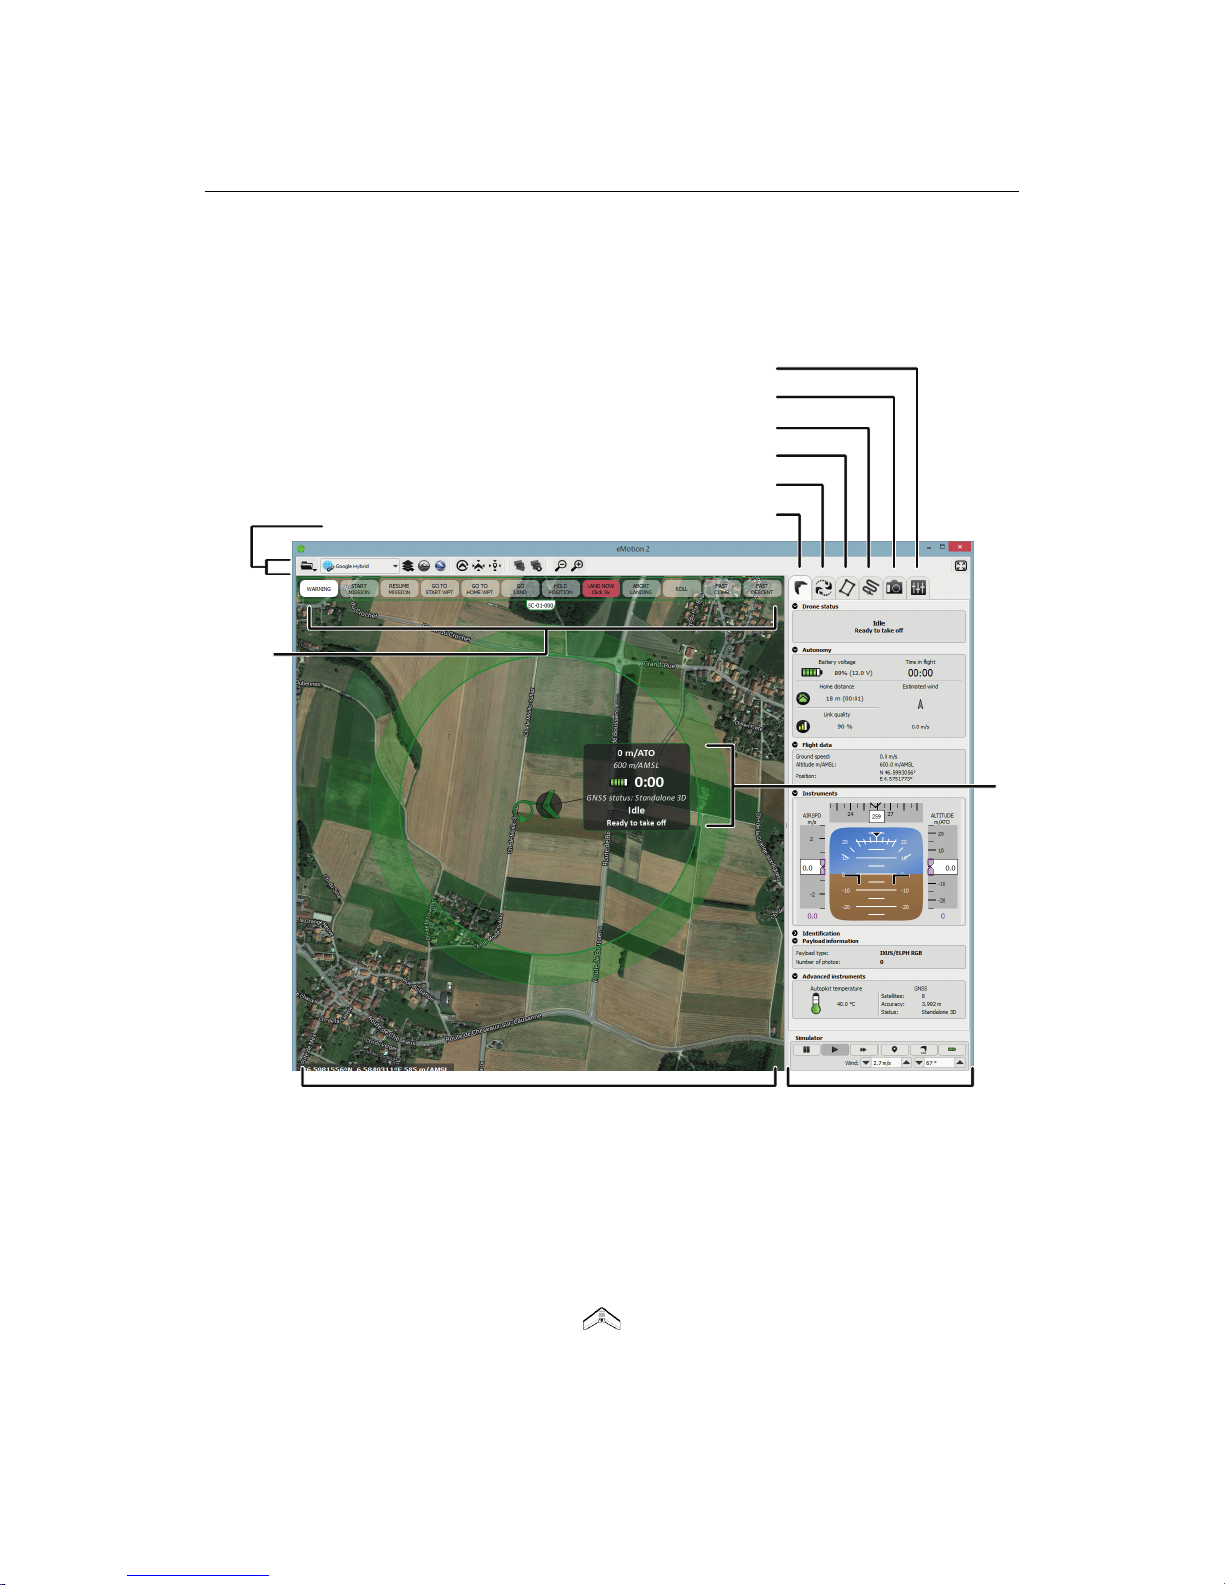
We recommend that you plan flights using a simulateddrone. Once connected to
a real or simulated drone you will see the main screen of eMotion.
SidebarMap Area
Control
Bar
Toolbar
Status
Panel
Flight Parameters tab
Camera tab
Mission Waypoints tab
Mission Planning tab
Setup Phase tab
Flight Monitoring tab
The main screen of eMotion is split into four sections:
• Map Area: The Map Area of eMotion displays a map with the drone’s cur-
rent position, indicated by the symbol. A small Status Panel floats besidethesymbol,indicatingimportantstatusinformationincluding the swinglet CAM’s
18
Page 19
Planning and simulating a flight
currentaltitude(both Above the Take-off Altitude, markedasATO,and Above
Mean Sea Level, marked asAMSL), battery level, flight time, and status. The
Status Panel can be hidden by clicking on the drone. Moving around the
map is done by clicking and dragging at any place not occupied by a symbol (such as a waypoint or the drone symbol).
• Control Bar: The Control Bar is used to issue various commands to the
swinglet CAM while itis in flight, such as starting the mission phase or holding position. It is also used to display and acknowledge warnings that may
occur either before or during a flight.
• Toolbar: The Toolbar contains buttons to control the layers,sourcesor map
informationandotherdisplayoptionsrelatedto the Map Area. eMotion can
use many sources of mapping information.
• Sidebar: The Sidebar is split into several tabs, each with a particular func-
tion. The Flight Monitoring tab is used for monitoring the drone while in
flight. The Setup Phase tab controls the take-off and landing portions of
a flight plan (referred to as the ‘setup phase’) whereas the Mission Planning tab defines the image acquisition portion of the flight plan (referred
to as the ‘mission phase’). The last three tabs are used for advanced waypoint planning and parameter setting. Youcan hide the Sidebar byclicking
on its left edge. The Sidebar also contains controls for the simulator when
connected to a simulated drone.
1.3 Creating a new flight plan
Every mapping flight requires a flight plan, which is a path defined by a set of
waypoints, or points in 3D space, and a set of actions that can be performed at
or in between waypoints, such as taking images, proceeding to the next waypoint or landing. A flight plan is shown in the Map Area using circles to represent
waypoints, lines to represent the flight path and arrows to show the direction of
flight. The large circle with a thick border illustrates the working area boundaries
within which the swinglet CAM will always remain. See section ‘Waypoints and
19
Page 20
Quick start guide
their properties’ on page 50 for more information on waypoints and the various
symbols presented in the Map Area.
A complete flight plan for a swinglet CAM is divided into two separate phases: the
setup phase and the mission phase. The mission phase includes waypoints and
actions related to mapping and capturing images. The setup phase includes waypoints and actions related to take-off and landing. This phase is usually planned
directly in the field andis explainedin detailin section‘The setup phase of a flight’
on page 33.
1.4 The mission phase of a flight
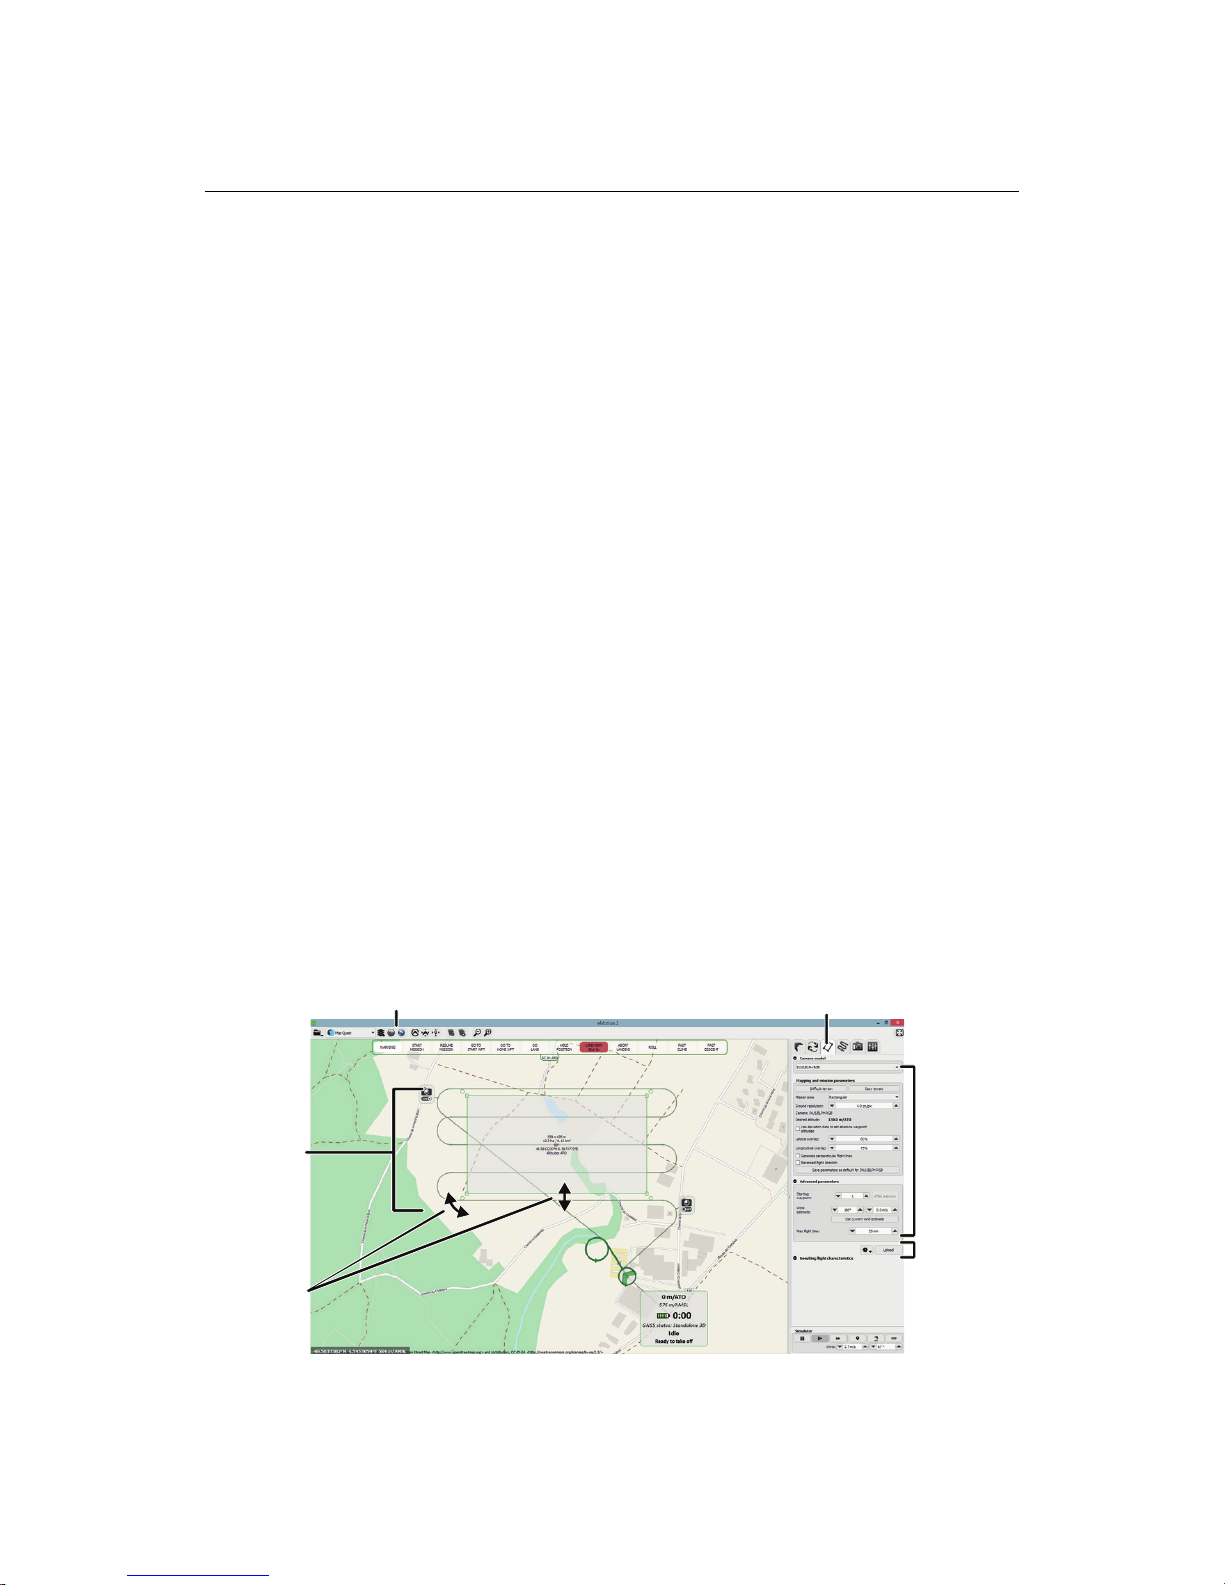
The easiest way to createa mappingflight for the systematic coverage of an area is
to use the automatic missionplanning feature of eMotion. Bysimply positioning a
rectangle around the area you would like to cover,eMotion will generatea mission
plan optimised for the ground resolution that you desire.
mission
area
Step 1: open tab and select
Step 2:
rotate,
resize,
move
Step 3:
choose
params
Step 4:
upload
Step 5: check in Google Earth
correct camera
20
Page 21
Planning and simulating a flight
Note: For more complex terrain and missions, eMotion has the abil-
ity to set polygonal mission areas of any size and shape, and to automatically adjust waypoint altitudesbased on elevation data. These
powerful features are described in more detail in section ‘Advanced
polygonal mission area’on page 55and section ‘3D mission planning
using elevation data’ on page 56, respectively.
Follow these steps to automatically setup waypoints for a mapping mission:
1. Select the Mission Planning tab from the Sidebar. A grey zone will appear
in the Map Area to designate the mission area to cover. Information such
as size and position is overlaid on the area. A mission plan, including the
required waypoints, is automatically calculated and displayed to preview
the mission plan that will be created.
2. Adjust the location, size, and shape of the mission area. The area can be
relocated by dragging the gray zone. The four squarehandles onthe edges
of the area can be used to resize it and the round handles on the corners of
the area can be used to rotate it. As you adjust the area the mission plan
preview is continuously updated.
3. Adjust the mapping andmission parameters in theMission Planning tab to
suit your terrain and quality requirements¹. As a first step, eMotion provides
two predefined set of parameters; ‘Easy terrain’ are the default parameters
designed for simpler terrain, such as mines oragriculture, whereas ‘Difficult
terrain’ is designed for complex areas, such as forests, and provides higher
image overlap at the cost of a lower resolution. Be sure to include an estimated wind speed and direction, as this has an effect on the area that can
be covered in a single flight. Once again, the mission plan preview will be
continuously updated as you modify the parameters.
4. Check the resulting flight characteristics in the tab. Once you are satisfied,
upload the mission plan to the simulated drone by clicking the ‘Upload’
button.
¹ see section ‘Mission Planning tab’ on page 86 for a complete description of available parameters
21
Page 22
Quick start guide
5. Click the button in the Toolbar to openthe flightplan in Google EarthTM².
Review the flight plan to ensure that there is sufficient clearance between
the flight plan and the ground. Any updates to the flight plan that you
make within eMotion will be reflected directly in Google EarthTM.
Caution: eMotion as well as the automatic mission planning tool are
not aware of any obstacles that may exist in the area. In addition,
when not using elevation data, the mission planning tool assumes
that the missionarea is flat andat the same altitude than the take-off
location. It is also not aware of any legal restriction (suchas minimum
or maximum altitude) that may exist in your region. The resulting
flight plan should be carefullyreviewed in order to avoid any collision
with uneven terrain or tall objects such as buildings, and to comply
with local regulations.
The final step after you have prepared a flight planis tosave it toa filethat you can
load into the swinglet CAM when you are in the field. Select the Setup Phase tab
from the Sidebar, click on ‘Saveflight plan to file...’, choose afilename and location
and click ‘Save’.
1.5 Simulating your flight
Simulating your flight gives you an idea of the position and size of images that
will be taken during the flight. In addition, it allows you to learn to use advanced
functions, such as in-flight waypoint editing and camera control, without putting
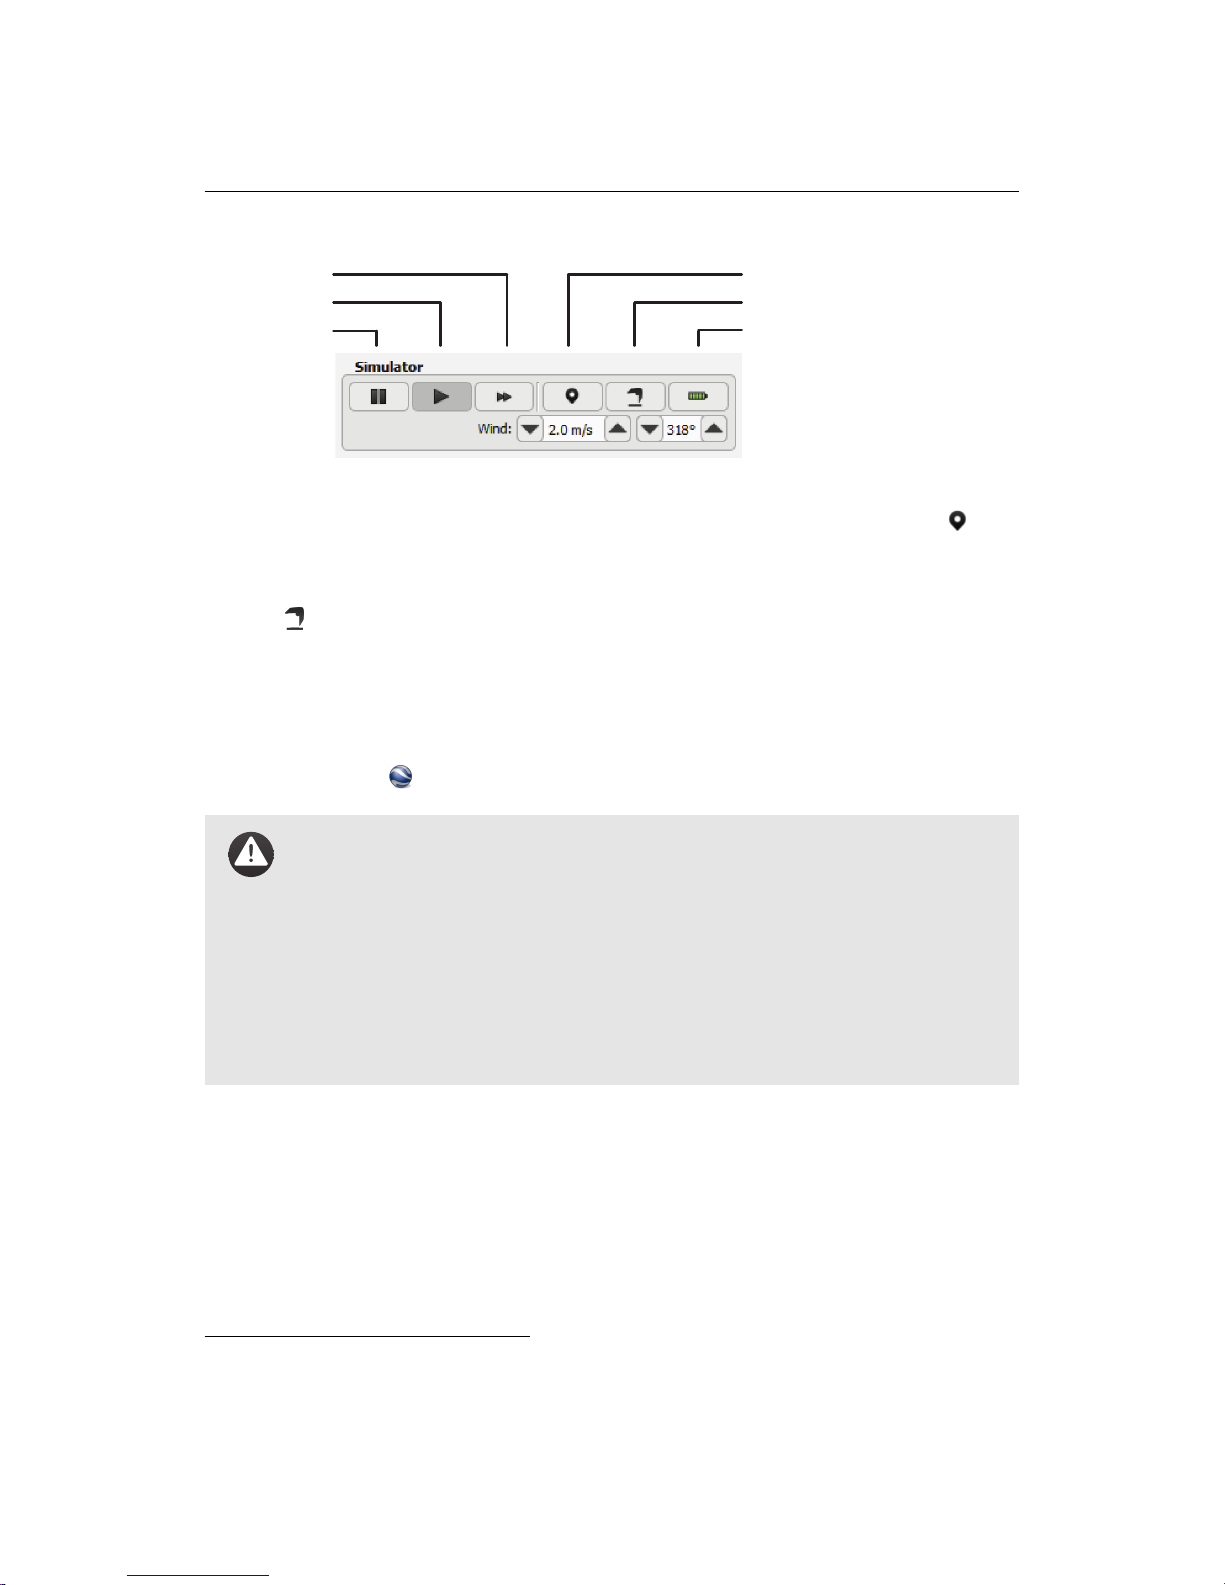
your swinglet CAM at risk³. When eMotion is connected to a simulated drone an
extra set of buttons appear in the Sidebar:
² see section ‘Flight visualization in Google EarthTM’ on page 58
³ see section ‘Simulator’ on page 74 for a complete description of the simulator
22
Page 23
Planning and simulating a flight
re-position take-off location
initiate take-off
instant recharge of battery
fast-forward
play
pause
You can set the take-off location of the swinglet CAM by clicking on the icon
and placing the point on the map. This simulates the action of switching on the
real drone and letting it acquire GPS signals. You can test your flight plan by clicking the icon, simulating a take-off manoeuvre. The swinglet CAM will then go
through its flight plan in the same way it would in the field. You can pause, play
or speed up the simulation by clicking the corresponding buttons in the Toolbar.
You can monitor the state of the drone while in flight using the Flight Monitoring
tab and the Status Panel⁴. Youmay also monitor the flight in 3D in Google Earth
TM
by clicking on the button in the Toolbar.
Caution: The simulator is a tool designed to aid with flight planning and to familiarise you with the advanced functions of your
swinglet CAM. The simulated physics, however, are basic and do not
always accurately reflect the true behaviour of the drone in flight. In
particular, estimates of battery level and reactions to wind are difficult to simulate with high accuracy. You should in no case dependon
behaviours seen with a simulated drone to be reproduced exactly in
real flight.
1.6 Getting ready for a mission
Beforeleavingfor the field to performaflight,besuretofully charge all your drone
batteries as wellas the camerabattery. When delivered, the swingletCAM battery
may not be fully charged.
⁴ see section ‘In-flight monitoring and control’ on page 39
23
Page 24
Quick start guide
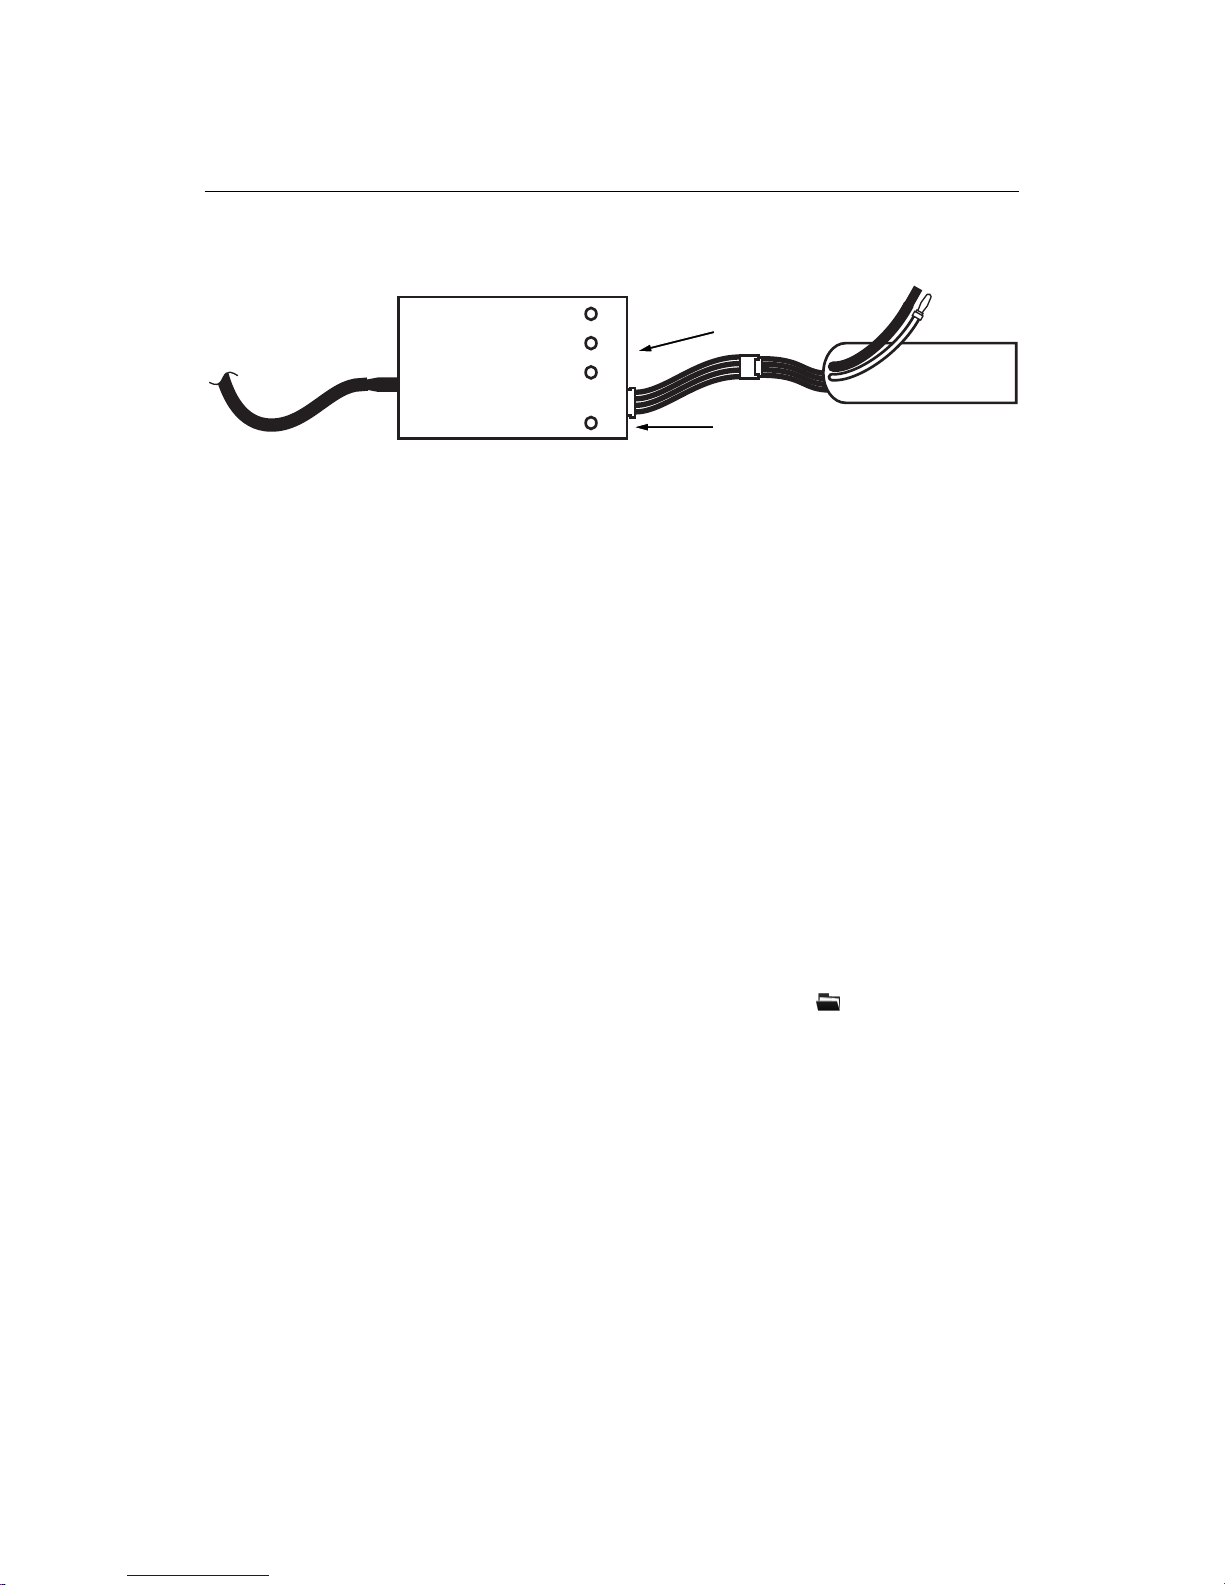
swingletCAM
battery pack
power cable
main power cables
leave disconnected
3
2
1
Status
LiPo Balance
Charger
balance LEDs
(not to scale)
status LEDs
To charge a swinglet CAM battery pack, connect it to the battery charger as illustrated above. Make sure that the main power cables of the battery are left disconnected. During charge, the status LED on the charger is solid red. Charging is
complete when the status LED turns green.
The charger provided independently balances the voltage of each of the 3 cells
contained in the battery pack to ensures optimal performance and battery life. If
any of the cells is unbalanced, its associated LED will be solid red during charging
until it is re-balanced. Charging can take up to an hour, depending on the charge
level of the battery and the required cell balancing work. See section ‘Proper battery care’ on page 123 for more information on maintaining your drone’s batteries.
To charge the camera battery, remove it from the camera and insert it into its
charger. Plug the charger into a power outlet. The charge LEDbecomes red when
charging begins. Once the battery is fullycharged, the LED turns to green. Charging takes approximately 1 hour and 30 minutes.
If you plan on performing a flight away from an Internet connection it is useful to
preload map tiles by selecting ‘Download maps...’ from the File menu. More
details on how to take advantage of the various map sources available in eMotion
can be found in section ‘Toolbar’ on page 71.
24
Page 25
Executing a flight
2 Executing a flight
Goal of this section: This section describes how to prepare your
swinglet CAM for flight, launch, monitor and control from the air, and
initiate an autonomous landing.
Note: We recommend that you perform your first flight in a large
obstacle-free area and limit the length of the mission in order to familiarise yourself with the swinglet CAM in flight.
2.1 Weather check
Beforeeach flight, you should be awareofthe weather conditions. TheswingletCAM
is a small drone that cannot fly in heavy rain or strong wind conditions. In case of
doubt, make sure to check a weather bulletin including wind estimations in the
flight area. Note that wind is often stronger at higher altitudes and that the wind
perceived at the surface is not always a good reference to estimate the wind at
flight altitude. Cloud velocity or tall treemovements can help youto estimate the
wind speed once you are out in the field.
Weather forecasts may use various units to measure wind speed. As a reference,
1 m/s = 3.6 km/h = 2.24 mph = 1.94 kts.
Caution: The swinglet CAM should not be launchedifthe wind speed
exceeds 7 m/s (in other units: 25 km/h, 15.6 mph, 13.6 kts).
Caution: The swinglet CAM is not designed to fly in temperatures
above 35◦C. Avoid exposing the drone to high temperature for prolonged periods of time. In particular, leaving the drone exposed to
the sun or in a car should be avoided.
25
Page 26
Quick start guide
2.2 Preparing the swinglet CAM for flight
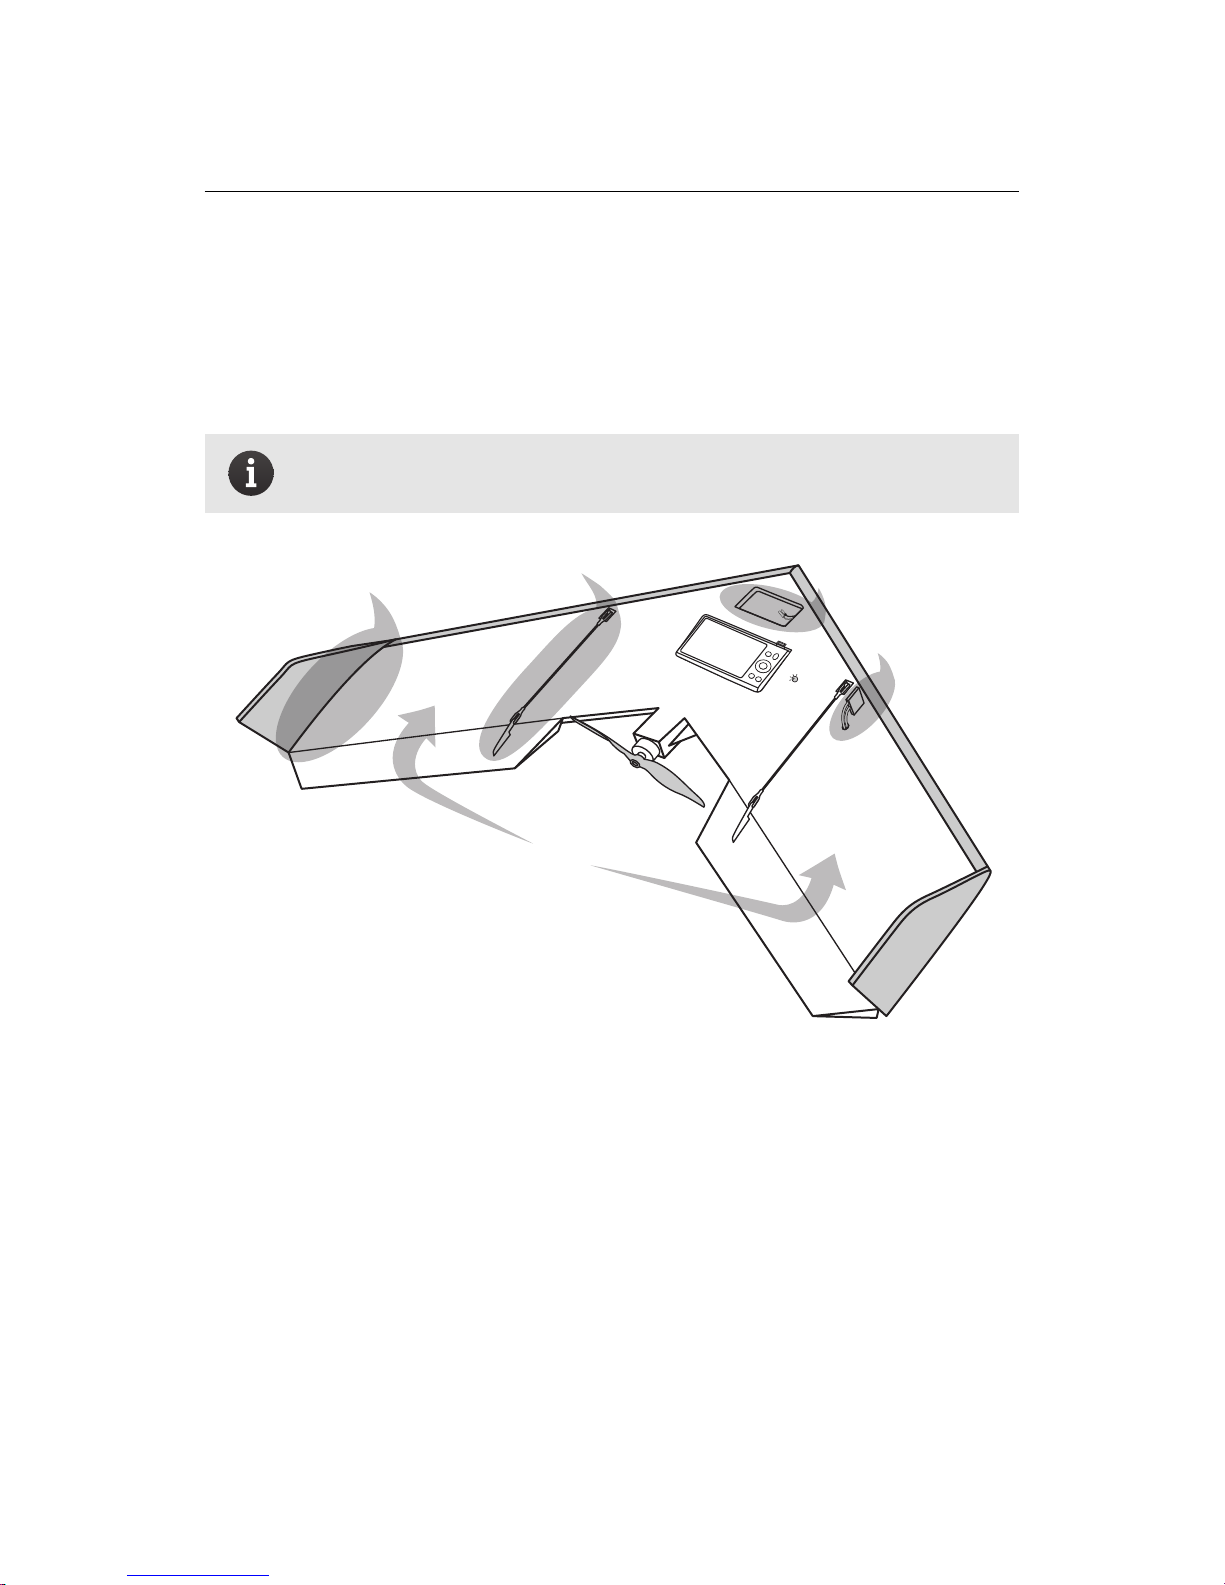
The swinglet CAM’s simple designmeans it can go from the box to being ready for
flight in minutes. We recommend that you perform the following 5 steps before
every flight to ensure that the platform is best prepared for flight.
Note: Remove the red warning sticker from the motor before your
first flight.
2
3
4
1
5
Step 1: Perform a general inspection
Visually inspect the drone for damage or wear using the following steps:
1. Check the foam airframe for cracks or other damage.
2. Verify that the winglets are solidly attached to the airframe.
3. Verify that the linkage between the servos and the ailerons are not damaged and firmly attached at both ends.
26
Page 27
Executing a flight
4. Verifythatthepitot probe is properly attached to the airframe, the two rubber tubes are well in place and that the holes in the probe are free of obstructions.
5. Verify that the power cables are well insulated and not damaged.
Note: A general inspection should be performed before every flight.
It is also good practice to perform a full airframe check regularly to
keep your swinglet CAM in good shape. See section ‘Full airframe and
sensor inspection’ on page 119 for more details.
27
Page 28
Quick start guide
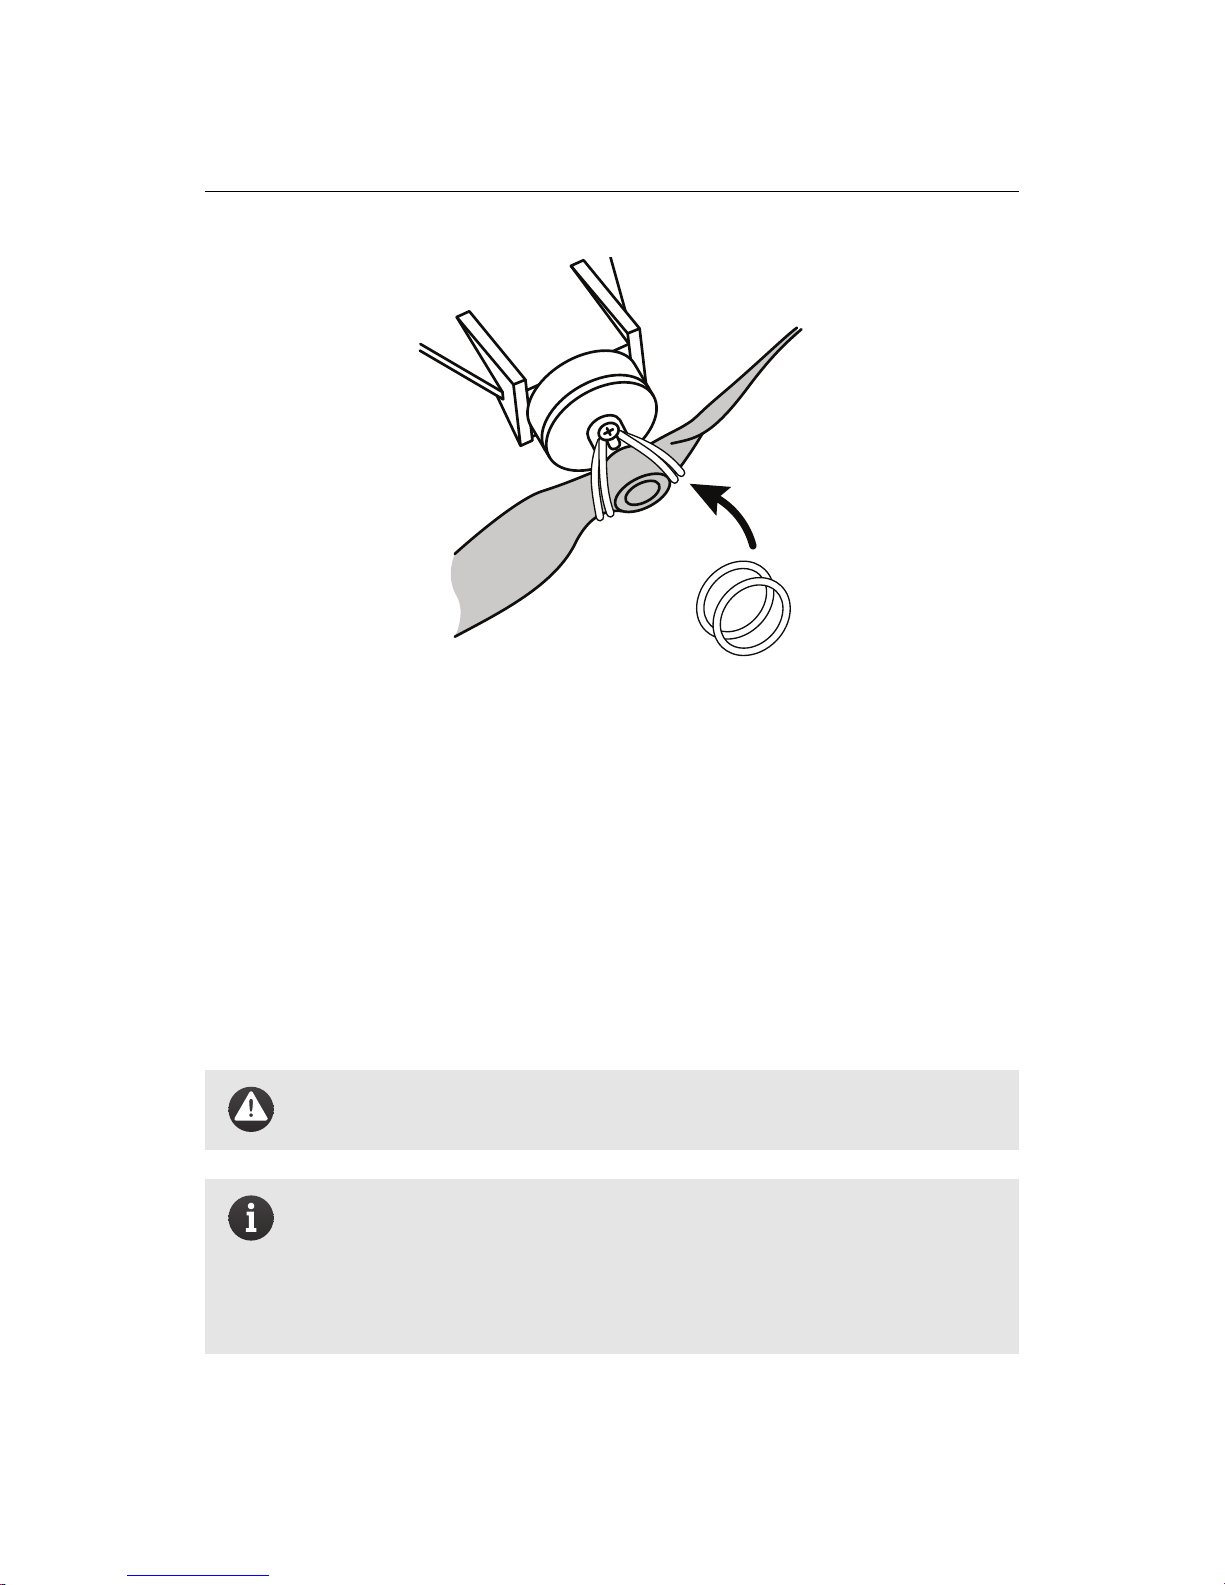
propeller
propeller
attachment
rubber bands
motor
Step 2: Install the propeller
Mount the propeller on the motor axis. Secure the propeller using two attachment rubber bands as illustrated above. Ensure that the propeller is lying flat
against the motor mount, and that the rubber bands do not show cracks or any
other sign of aging.
Caution: Failure to usetwo rubber bands may result in theloss of the
propeller in flight!
Note: After extensiveuse, the rubber bands may develop cracks. This
is normal and is caused by the ageing of the rubber material. Formaximum security, inspect the rubber bands regularly and discard them
if they show cracks. 10 spare rubber bands are included in the package.
28
Page 29
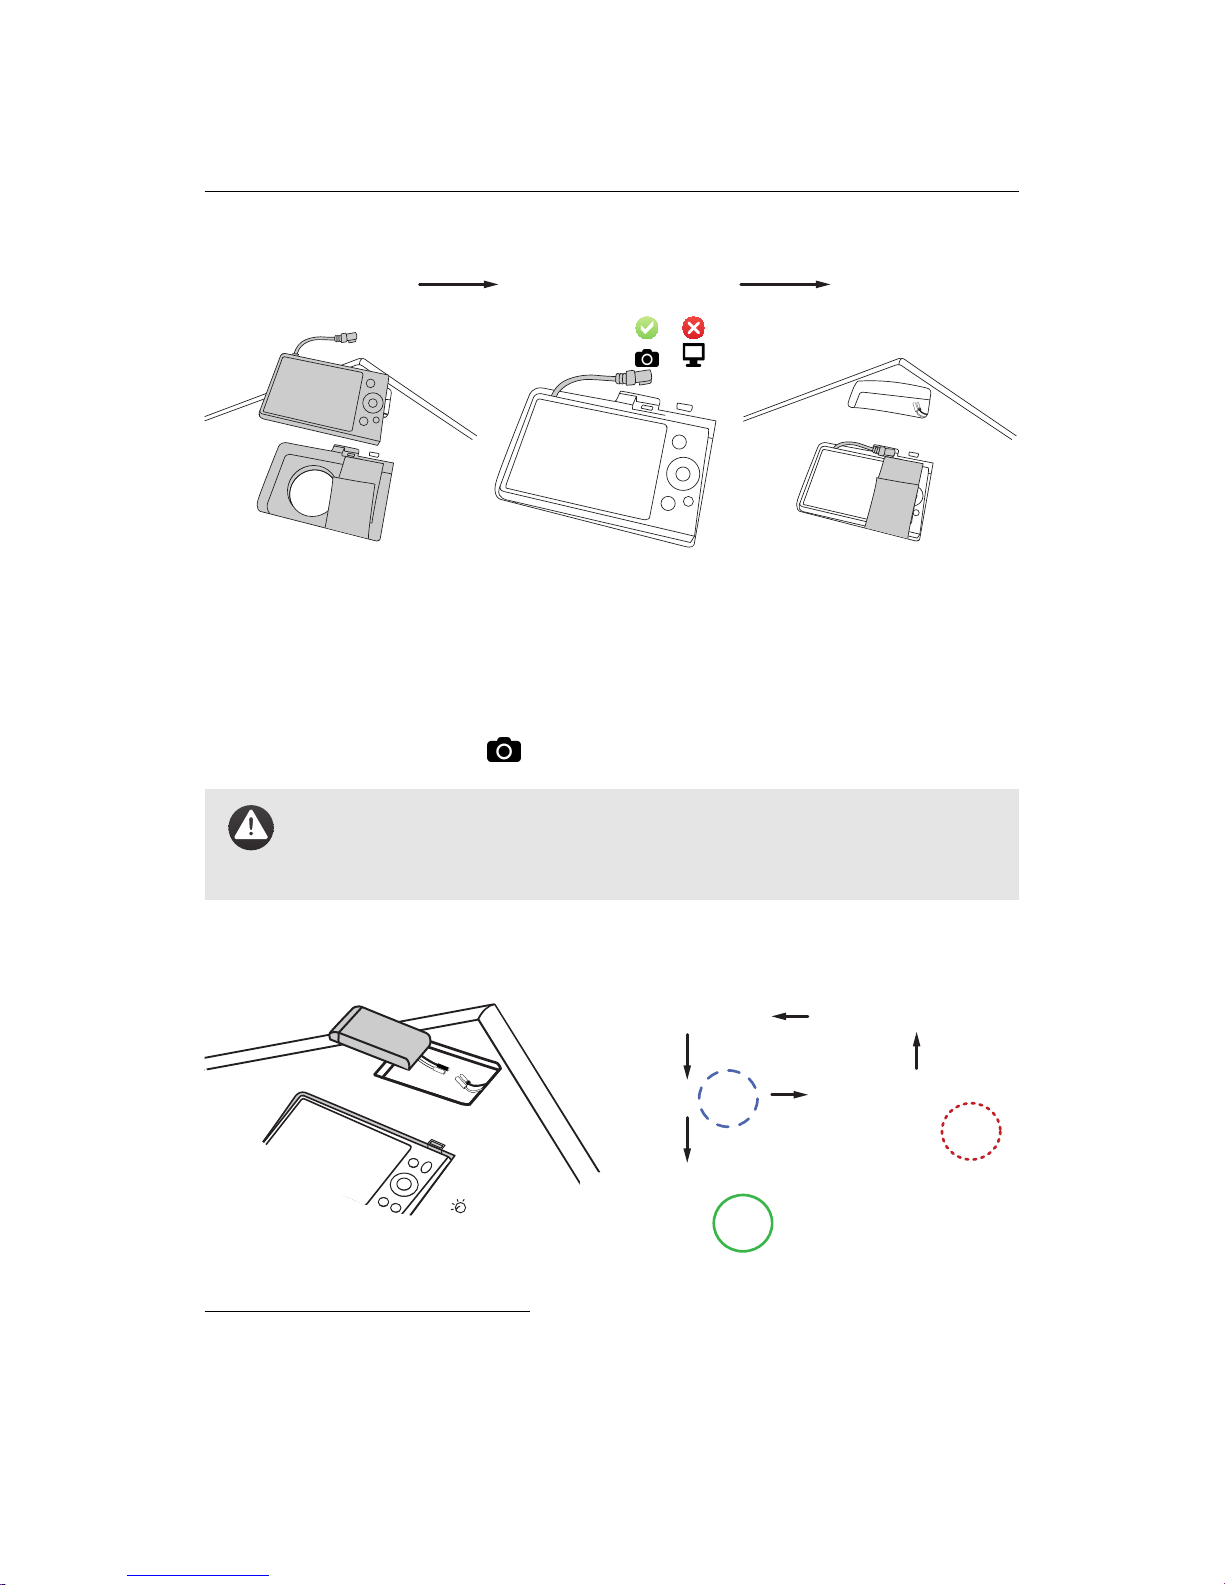
Executing a flight
insert camera into
compartment
plug in camera connector
to camera plug
attach velocro
straps
Step 3: Install the camera
Install the camera into the payload bay⁵ within the swinglet CAM and secure it with
the attachment strap. If the camera connector is not already connected, plug it
into the connector with the icon on the swinglet CAM.
Caution: The swingletCAM has not been designed to fly without the
camera. Attempting to fly without the camera may render the drone
unstable, which may eventually lead to a crash.
preflight checks failed
blue
pulse
status LED:
green
solid
status LED:
ready for startup
connect battery
red
blink
status LED:
disconnect battery
⁵ Some payloads may require a separate battery or SD card to operate properly. Please refer to the
User Manual of the camera or other payload for proper installation instructions.
29
Page 30
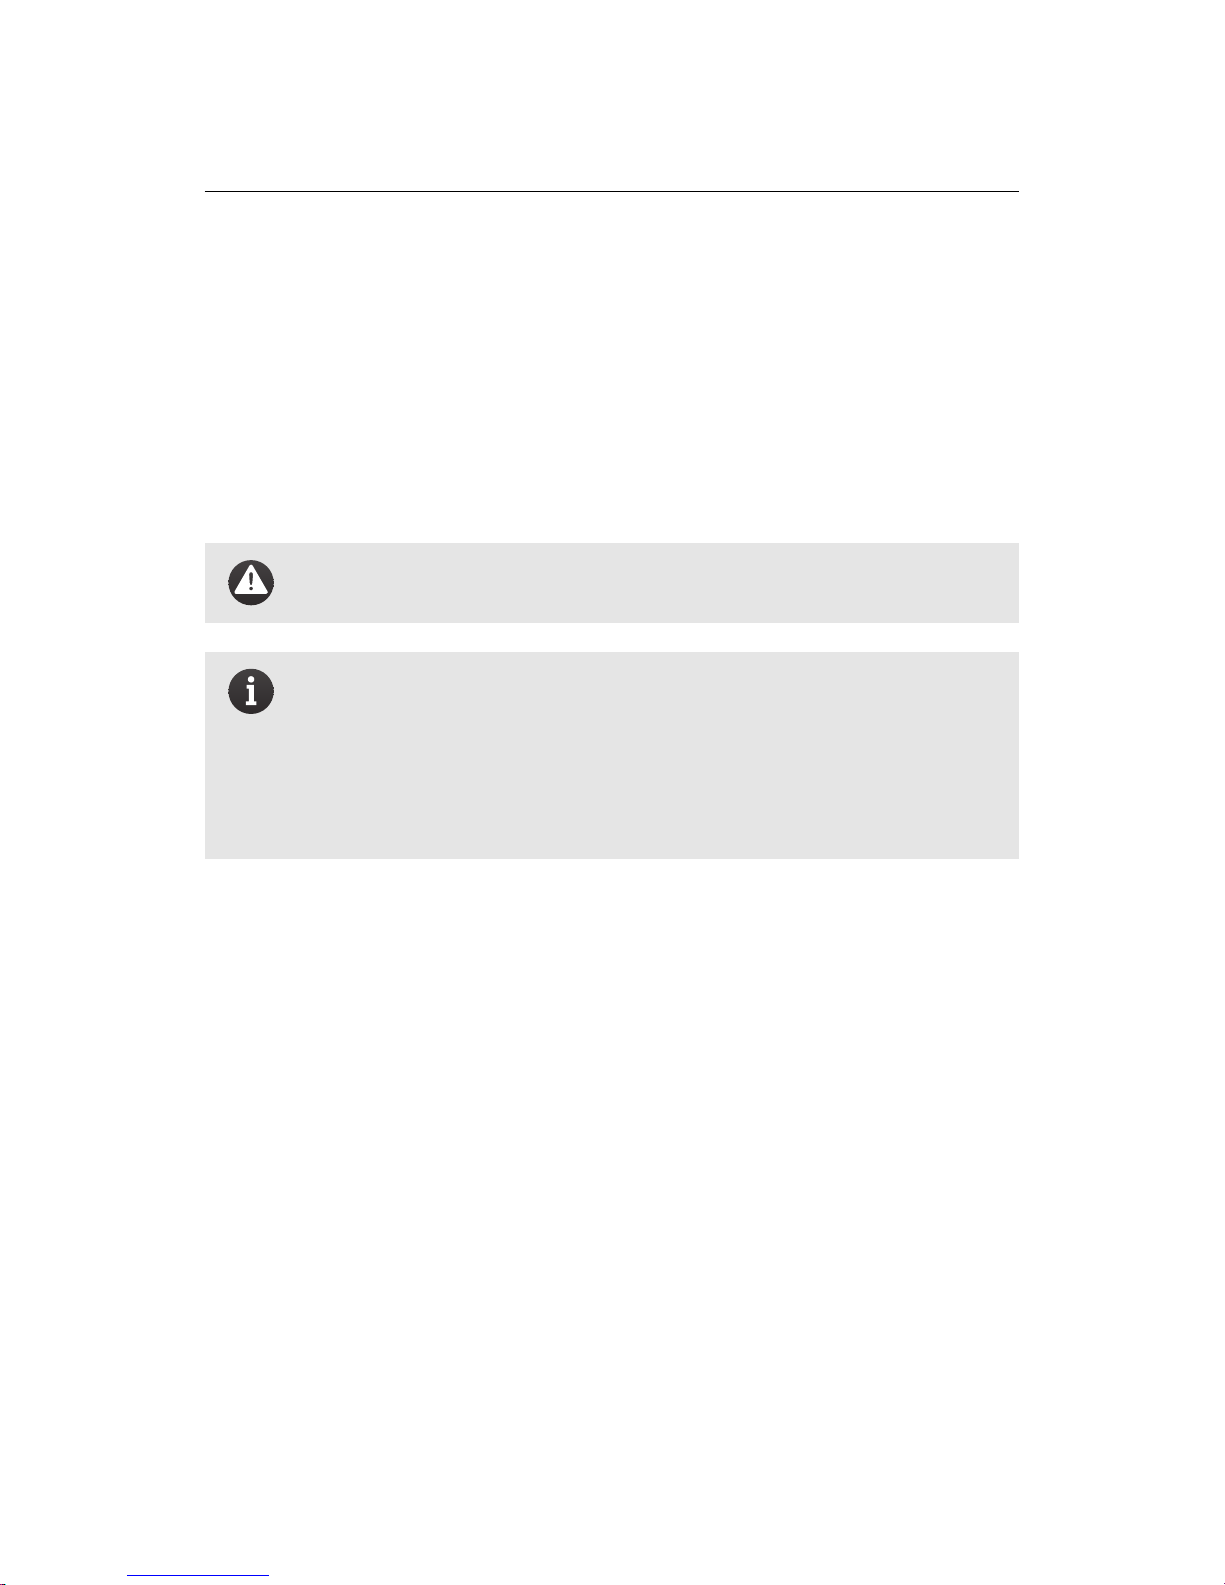
Quick start guide
Step 4: Install and connect the battery
Lay the swinglet CAM horizontallyonthegroundoutsideinthevicinity of the takeoff location, with the top face up. To install the battery, begin by connecting the
power cables to the battery, making sure to match the colours of the cables to
each other. Insert the connectors firmly to the end in order to avoid undesired
disconnection when in flight. Once connected, insert the battery into its compartment. Make sure that the battery is well attached to the drone by applying
vertical pressure.
Caution: Take care to keep the propeller area clear, in case it suddenly starts spinning.
Note: Only connect the battery cables to the drone when you are
ready for start-up. Do not leave the battery connected for extended
periods of time when the drone is on the ground, as this may discharge the batteriesand cause irreparabledamage. Whenconnected
and not in flight, the
swinglet CAM
will briefly moveitsaileronsupand
down every minute as a reminder that it is switched on.
As soon as the battery is connected the swinglet CAM will perform an automatic
self-check of its sensors and acquire GPS signals. Be sure not to move the drone
during these tests. It is important that the drone is not inclined more than 10 degrees in order to start up properly. Pre-flight checks may last from a few seconds
to several minutes in the case of poor GPS signal reception. As these satellite signals are required for the checks to complete, be sure to place the swinglet CAM
outside with a clear view of the sky.
During the pre-flight checks the status LED will pulse blue. Once the pre-flight
checks are complete the swinglet CAM will flip its ailerons up and down and the
status LED will turn solid green to indicate it is ready. You may already connect
the drone to eMotion (Step 5) before pre-flight checks are complete to get a better
idea of the status of the checks.
30
Page 31
Executing a flight
Note: If there was any problem during the pre-flight checks performed by the drone this will be indicated by a Pre-flight error in eMo-
tion as well as a by the status LED blinking red. See section ‘Pre-flight
errors’ on page 127 for a description of possible Pre-flight errors and
how to handle them.
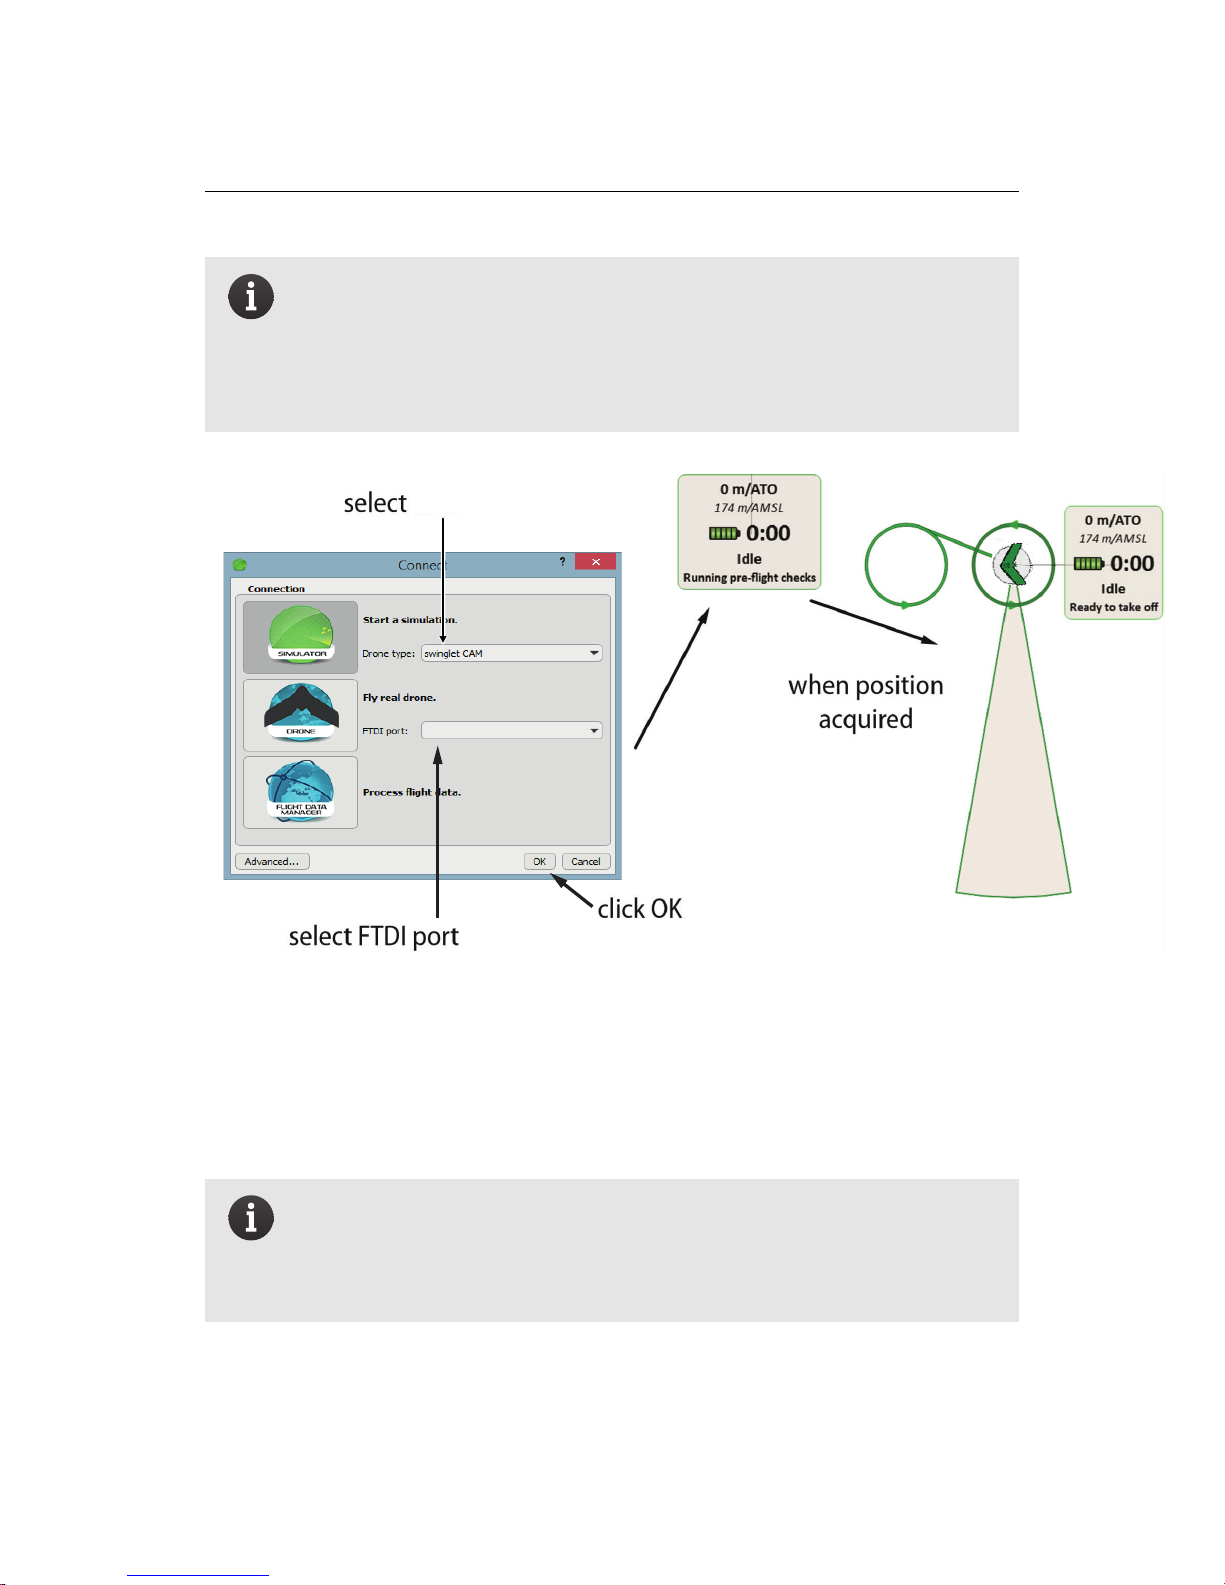
swinglet CAM
Step 5: Connect to eMotion
Start by connecting the USB ground modemto your computer. Thenlaunch eMotion, which will display the Connection window. Select the swinglet CAM connec-
tion profile, choose the corresponding FTDI port and click ‘OK’.
Note: EveryswingletCAM is paired with the groundmodemitisdeliv-
ered with, and will only work with that particular modem. The name
of the FTDI port corresponding to the ground modem is labelled as
‘MaxStream PKG-U’ followed by the serial number of the modem.
When a connection is established eMotion will display a map and the Status Panel
31
Page 32
Quick start guide
indicating the current state of the drone. If the swinglet CAM has not yet detected
its location the Status Panel will appear in the top right corner of the Map Area
with the text ‘GPS: Waiting for signals...’. During this time the status LED on the
drone will pulse blue.
Once your drone has set its position using GPS signals, an icon of the drone will
appear at its location onthe map. If the drone’s location is noton the map you can
click the button from the Toolbar to centre the map on the drone. The drone’s
status on eMotion will be displayed as ‘Idle, Ready to take-off’ and the status LED
will become solid green.
You can now load a flight plan you prepared earlier by selecting the Setup Phase
tab from the Sidebar, clicking on ‘Load flight plan from file...’ and selecting your
flight plan file. Alternatively, you can plan the entire missionin thefield, following
the same process outlined in section ‘Planning and simulating a flight’ on page 16.
32
Page 33
Executing a flight
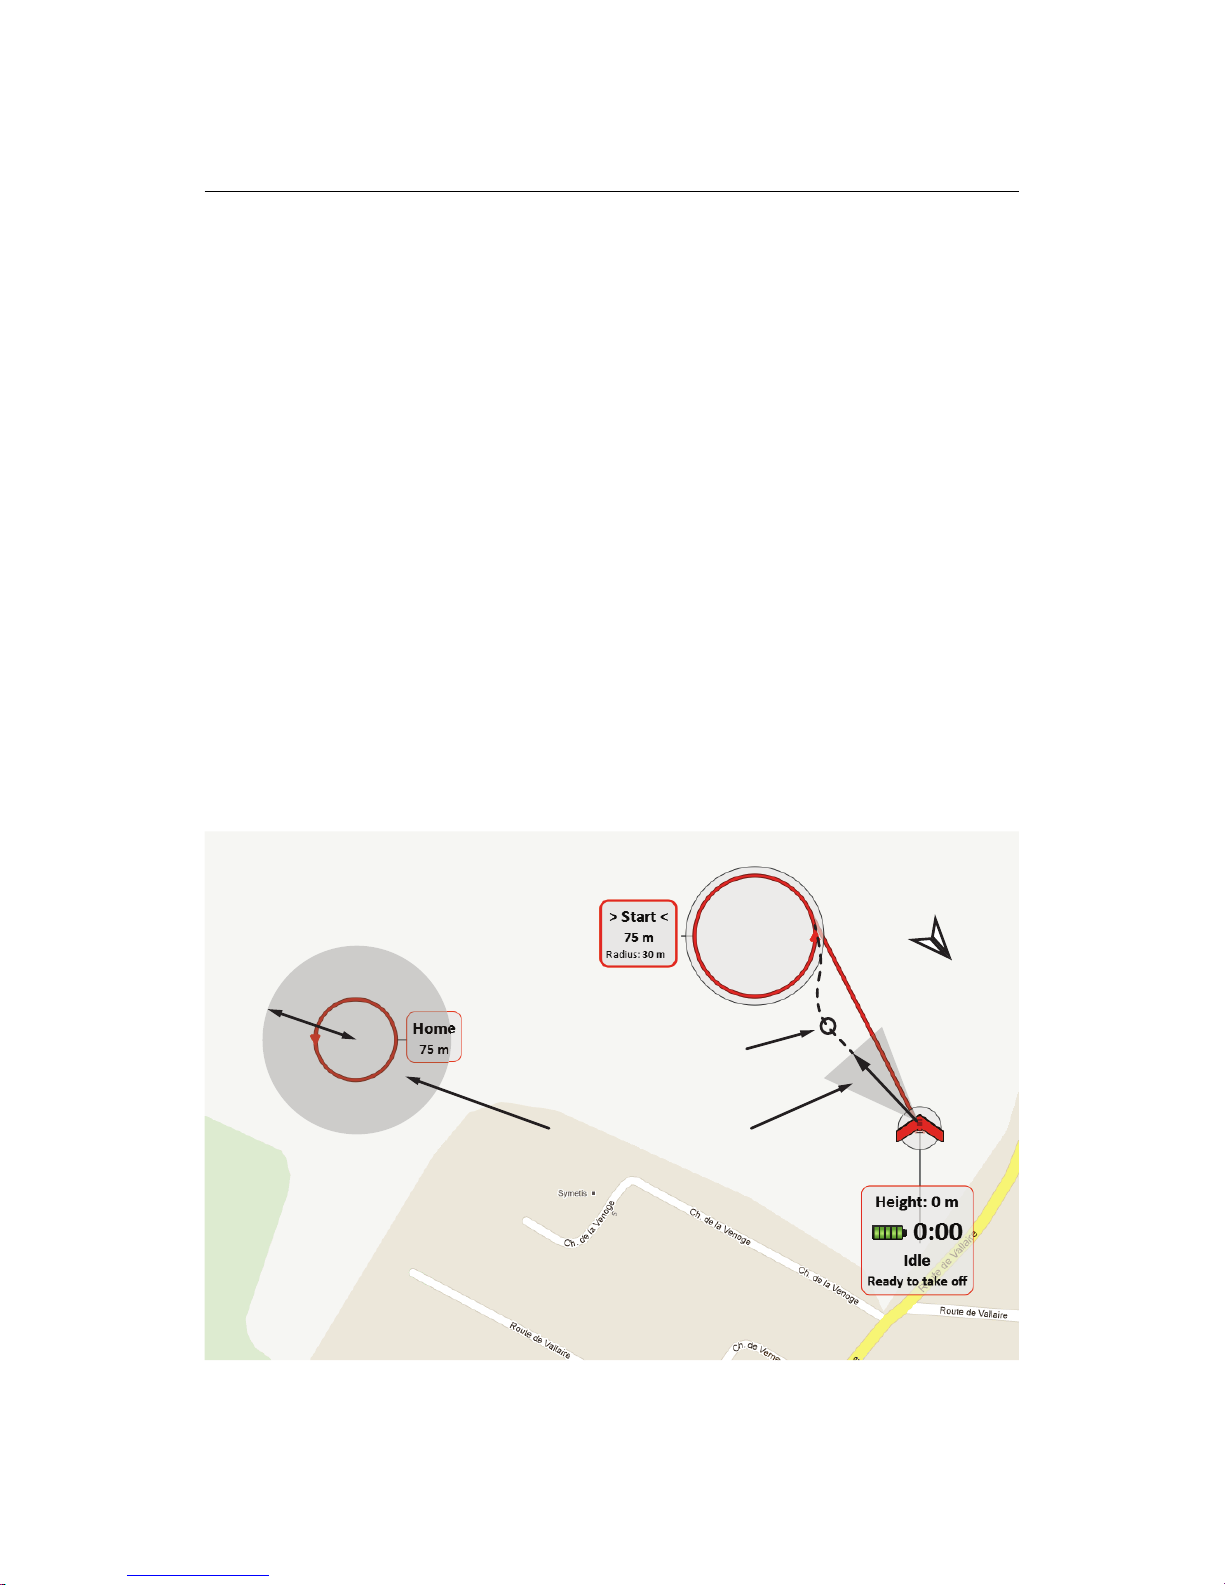
2.3 The setup phase of a flight
The setup phase of aflight includes the waypoints and actions related to the takeoff and landing of the swinglet CAM and includes the following locations:
• Take-off location: The point from which the drone is launched, automat-
ically set to the location calculated from GPS signals by the drone when
it is launched. This location defines the altitude of 0 m/ATO (ATO stands
for above take-off); the altitudes of all other waypoints, when defined in
m/ATO, are referenced to the altitude of this location.
• Start waypoint: Thefirst point that the drone flies towardswhenlaunched
(once it reaches the take-off transition altitude).
• Home waypoint: The safe point for the drone to circle in case of emer-
gency, as well as its landing position at the end of a flight for a Circular
landing.
wind
direction
obstacle-free
zones
40m
40m
launch
direction
take-off transition
altitude reached
33
Page 34
Quick start guide
It is important to carefully select the take-off location, the Start waypoint and the
Home waypoint to ensure your drone remains at a safe distance from obstacles.
The swinglet CAM should always be launched against the wind. Select a take-off
location clear of obstacles (buildings, rocks, power lines, hills, trees, etc.) within
a distance of at least 40 m in the upwind direction. Immediately after takeoff it
will keep its wings level and climb in the general direction it was launched until it
reaches the take-off transition altitude⁶, at which point it will start flying towards
the Start waypoint.
By default, the Start waypoint is set to a distance of 80 m West of the initial position of the drone andan altitudeof 75 m/ATO. It is good practiceto move the Start
waypoint close to and upwind from the take-off location to allow asmooth transition between take-off and waypoint-directed flight. You can move waypoints by
clicking on them and dragging them within the Map Area⁷.
The Home waypointisused both as the landing location and as a safety position in
case of an In-flight warning. When initiating a Circular landing around the Home
waypoint the drone will switch off itsmotor and glide down while circling around
the Home waypoint at the waypoint’s radius until it touches the ground.
To prepare a Circular landing, place the Home waypoint in a location that has no
obstacles within a radius of40m(or20mmorethan the Home waypoint radius) to
givethedrone enough space to land. Bydefault,theradius of the Home waypoint
is 20 m. In high-wind conditions it is recommended to increase this diameter⁸.
Note: In case of strong-wind conditions, the drone may drift even
further than 40 m away from the center of the Home waypoint when
performing a Circular landing. Therefore, it is safer to plan for even
more clearance in the downwind direction.
⁶ By default the take-off transition altitude is set to 20 m. In difficult launch conditions you can set
both the take-off heading and the take-off transition altitude in the Setup Phase tab, as described
in section ‘Setup Phase tab’ on page 82.
⁷ see section ‘Waypoints and their properties’ on page 50 for a more detailed explanation on way-
points and how to modify them
⁸ see section ‘Setup Phase tab’ on page 82
34
Page 35
Executing a flight
By default, the Home waypoint is set to an altitude of 75 m/ATO. In case a Go to
Home Waypoint procedure is triggered during flight⁹ the drone will, by default,
determine the highest altitude between its current altitude and the Home waypoint’s altitude, and climb in a circle towards that highest altitude (if required).
Once it reaches this highest altitude it will then fly towards the Home waypoint.
Due to thisbehaviour, the altitude of the Homewaypoint should be selected with
care; it shouldbe at least 20m higher than the surrounding obstacles to avoid the
risk of a crash, but should not be set too high to reduce the effect of potentially
high winds and altitude and to prevent the drone fromgetting lost. Alternatively,
you can change the altitude transition behaviour within the Setup Phase tab. See
section ‘Waypoints and their properties’ on page 50 for more information on altitude transition behaviours and how to modify them.
2.4 Take-off
Once you’ve planned your mission and the swinglet CAM status LED is solid green
you can launch it using the procedure on the following pages.
Caution: Make sure to keep the propeller area free of allobstructions
at all times during the launch procedure.
⁹ either automatically due to an In-flight warning or manually using eMotion
35
Page 36
Quick start guide
n
o
h
o
l
d
i
n
g
z
o
n
e
d
a
n
g
e
r
z
o
n
e
green
solid
status LED:
blue
pulse
status LED:
Not horizontal!
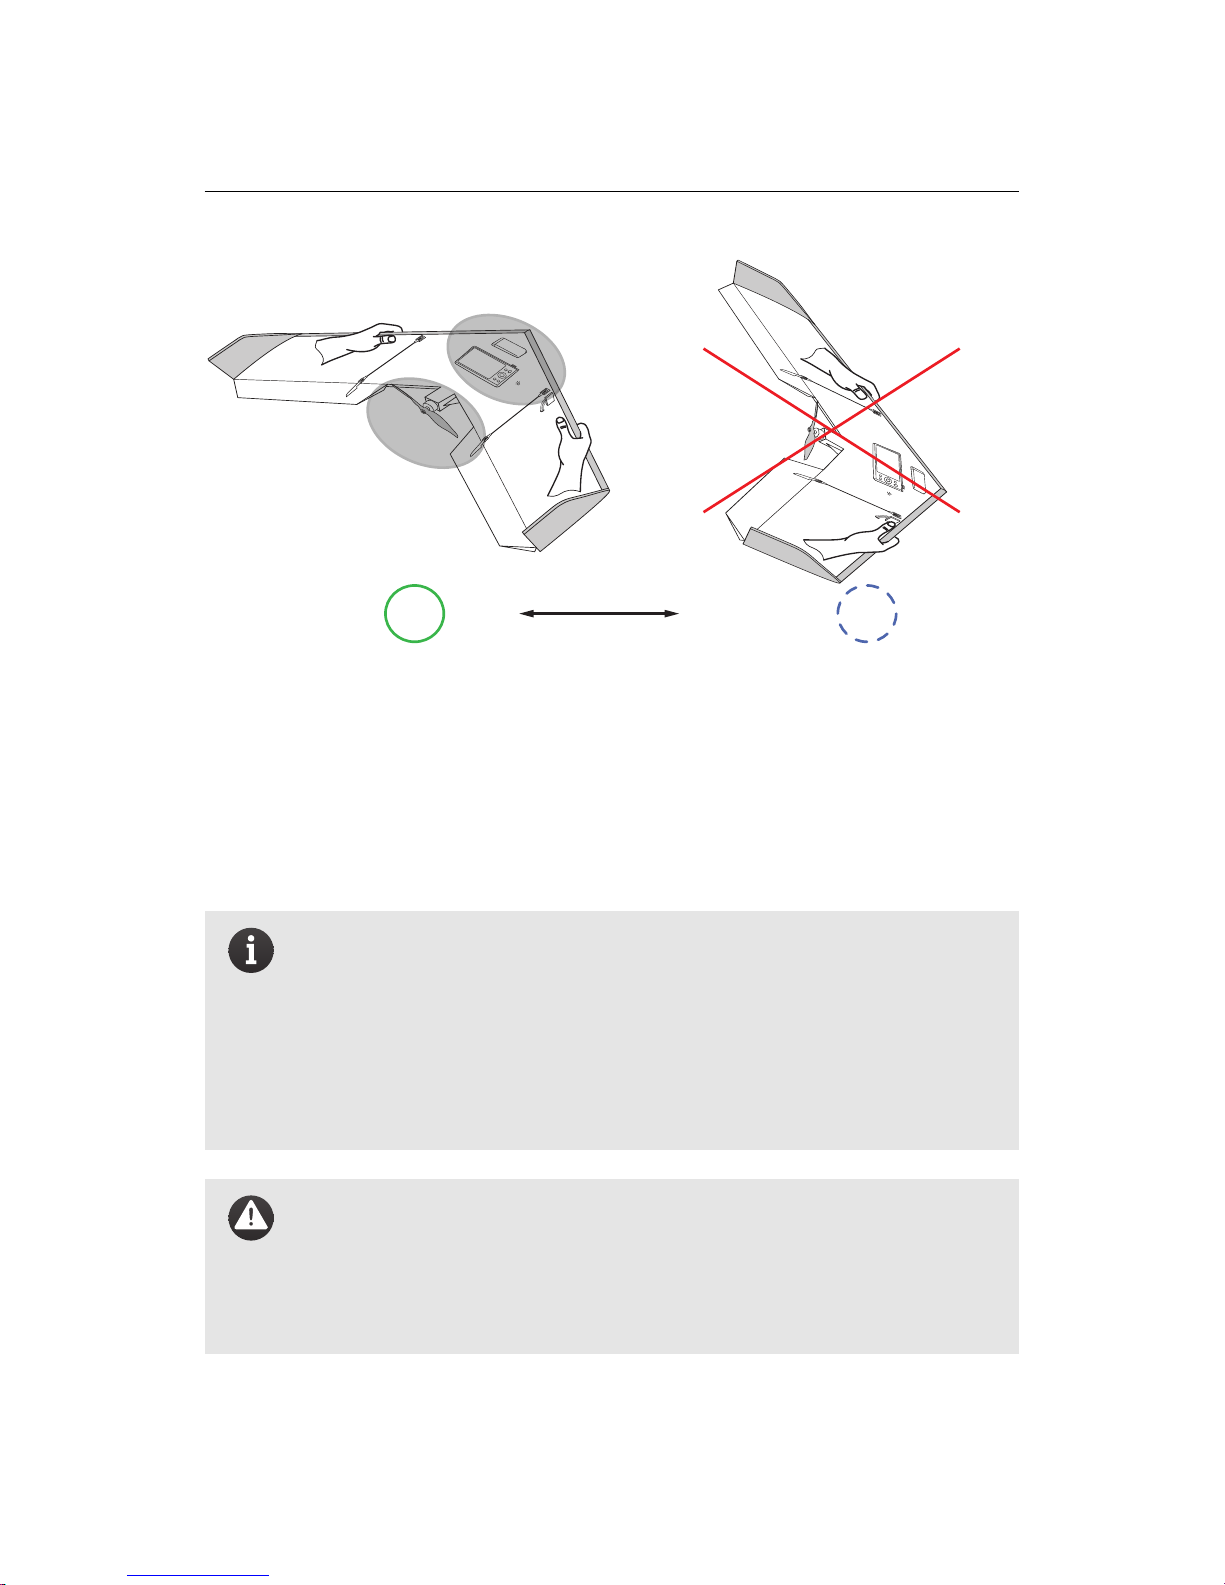
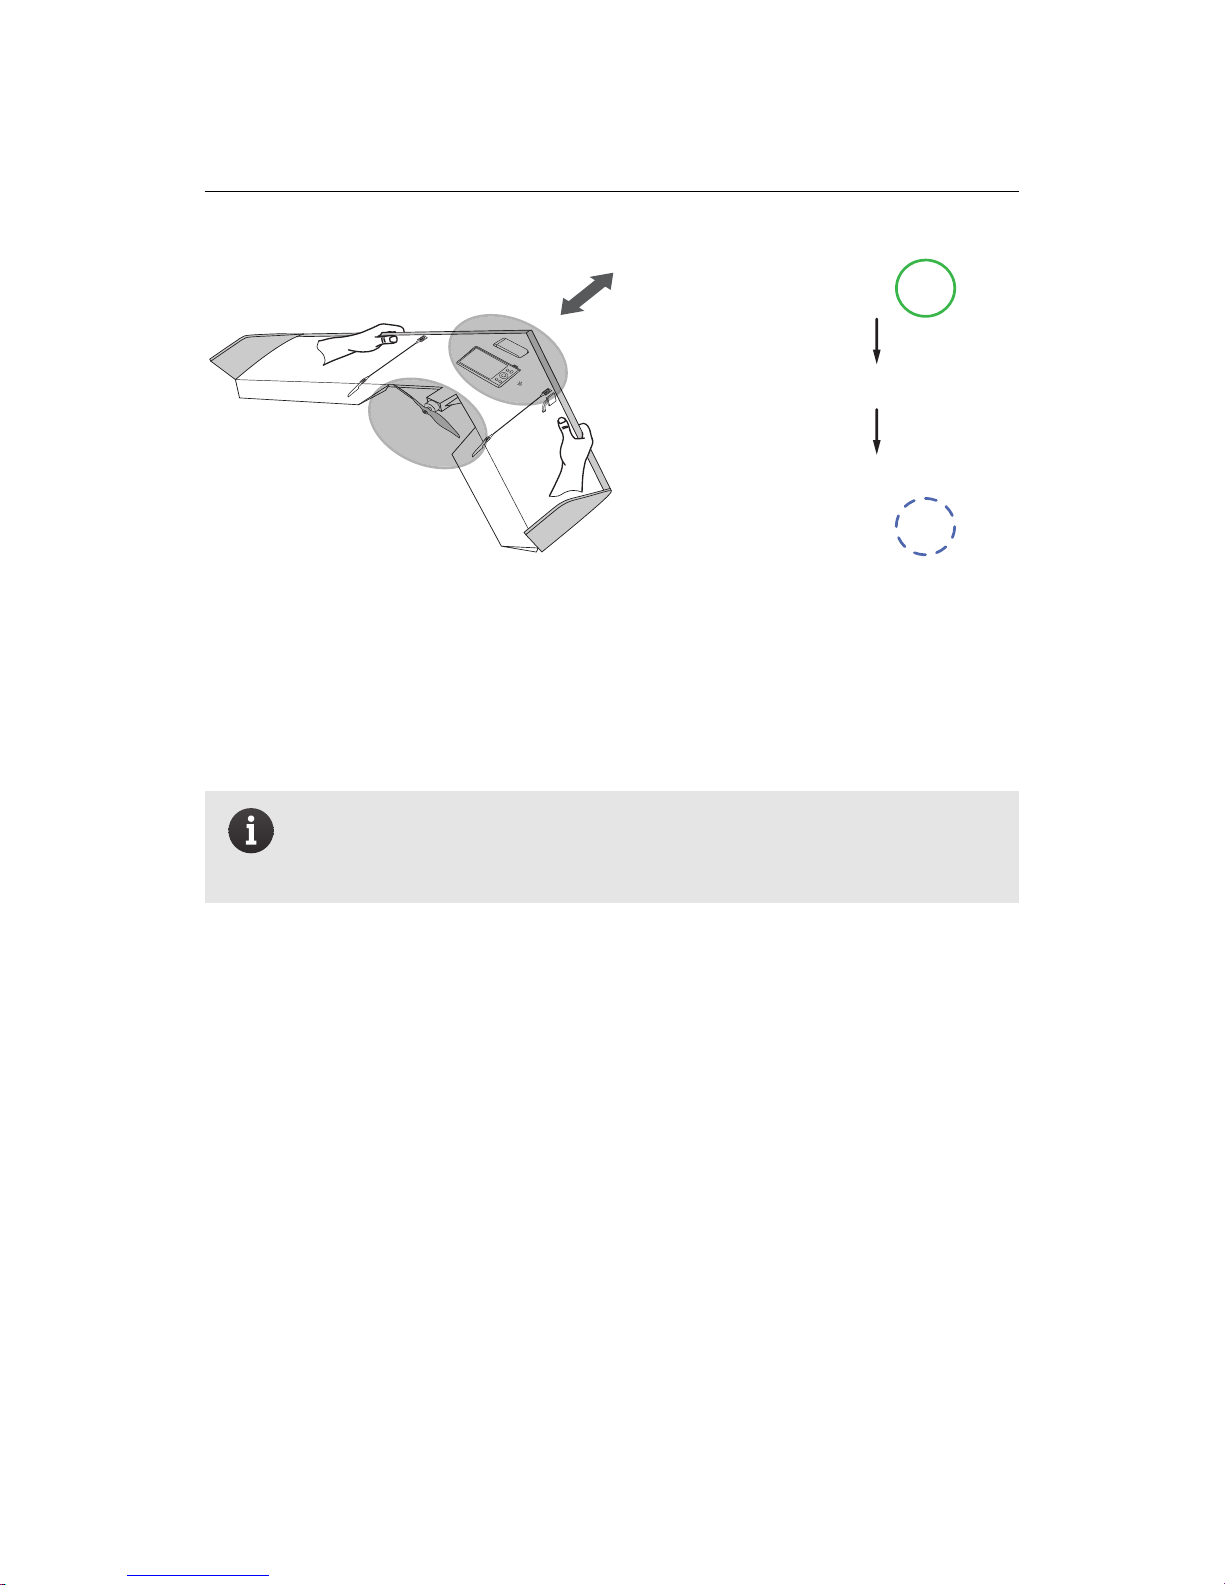
Step 1: Orient horizontally and against the wind
Orient yourself against the direction of the wind, and confirm that the take-off
direction in front of you is free of obstacles. Firmly grasp the drone with both
hands, one hand on the front of each wing as shown in the figure. Hold the drone
horizontally with the nose pointed against the wind and level wings.
Note: If the drone detects a condition that prevents correct take-off
a Take-off veto will be displayed in eMotion and the status LED will
start pulsing blue. Section ‘Take-off vetoes’ on page 130 describes
the possible Take-off veto messages and the user action that should
be taken to remove them. For example, if the drone is not oriented
horizontally the status LED will start pulsing blue until you re-orient
it horizontally, at which point the status LED turns solid green again.
Caution: It is imperative to launch the drone directly against the
wind, otherwise it will be unable to gain enough speed during takeoff and likely crash. Likewise, launching the drone in high winds
above the specified safe wind speed of 7 m/s is dangerous and can
result in a crash.
36
Page 37
Executing a flight
shake 3x
n
o
h
o
l
d
i
n
g
z
o
n
e
d
a
n
g
e
r
z
o
n
e
shake 3x
motor startup begin
green
solid
status LED:
blue
pulse
status LED:
Step 2: Switch the motor on
Shake the swinglet CAM back and forth 3 times longitudinally (within approx. 3
seconds) to begin the motor power-up sequence. The status LED will pulse blue
until the motor is at full power and ready for take-off.
Note: You do not need to hurry to launch the drone. In case you want
toshutoffthe motor, just repeat the back and forth action three times
and the motor will stop.
37
Page 38
Quick start guide
motor ready for take-off
green
blink
status LED:
blue
pulse
status LED:
green
solid
status LED:
step forward and release
10°
Caution: always orient the swinglet
against the wind for take-off!
place nose up 10°
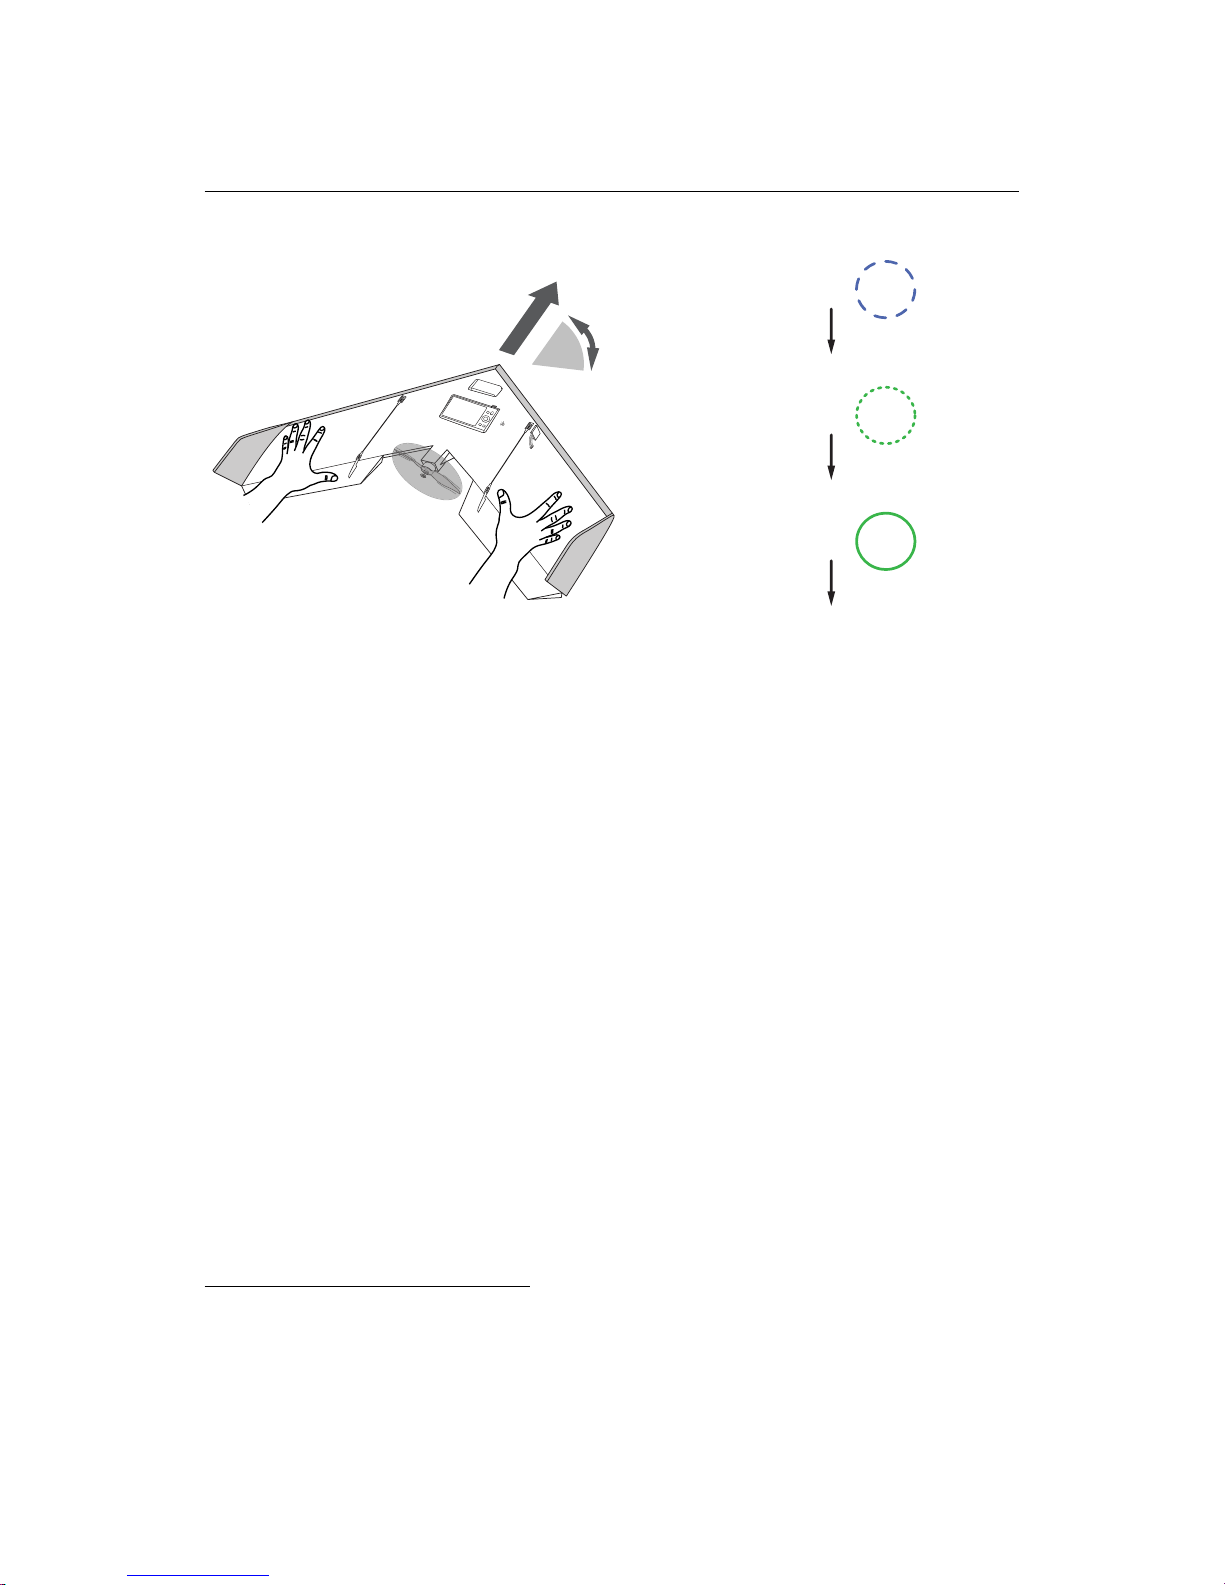
Step 3: Launch the swinglet CAM
Once the motor is at full power the status LED will blink green. Orient the drone
with approximately10 degrees nose up and level wings. When the angle is correct
the status LED will turn solid green, indicating that the drone is ready for take-off.
Launch the drone with agentle pushby walking1-2 steps forward while releasing
it with both hands in a purely forward motion.
After take-off, the drone tries to maintain its initial direction, or follow the directional take-off heading you set, by keeping its wings level with full thrust until
reaching the take-off transition altitude, by default 20 m¹⁰. At this point, it will
switch into waypoint navigation mode and fly towards the Start waypoint. Once
it reaches the Start waypoint location and altitudethe drone will circle around the
waypoint 1-2 times to estimate the wind and calibrate its sensors before starting
the mapping mission¹¹.
¹⁰ see section ‘Flight Parameters tab’ on page 102 to change this parameter
¹¹ The swinglet CAM may also be programmed to wait at the Start waypoint for a command before
starting its mapping mission. See section ‘Setup Phase tab’ on page 82 for more information.
38
Page 39
Executing a flight
Control Bar
Status
Flight Monitoring Tab
Wind speed and direction
Estimated
Panel
Picture
Footprint
2.5 In-flight monitoring and control
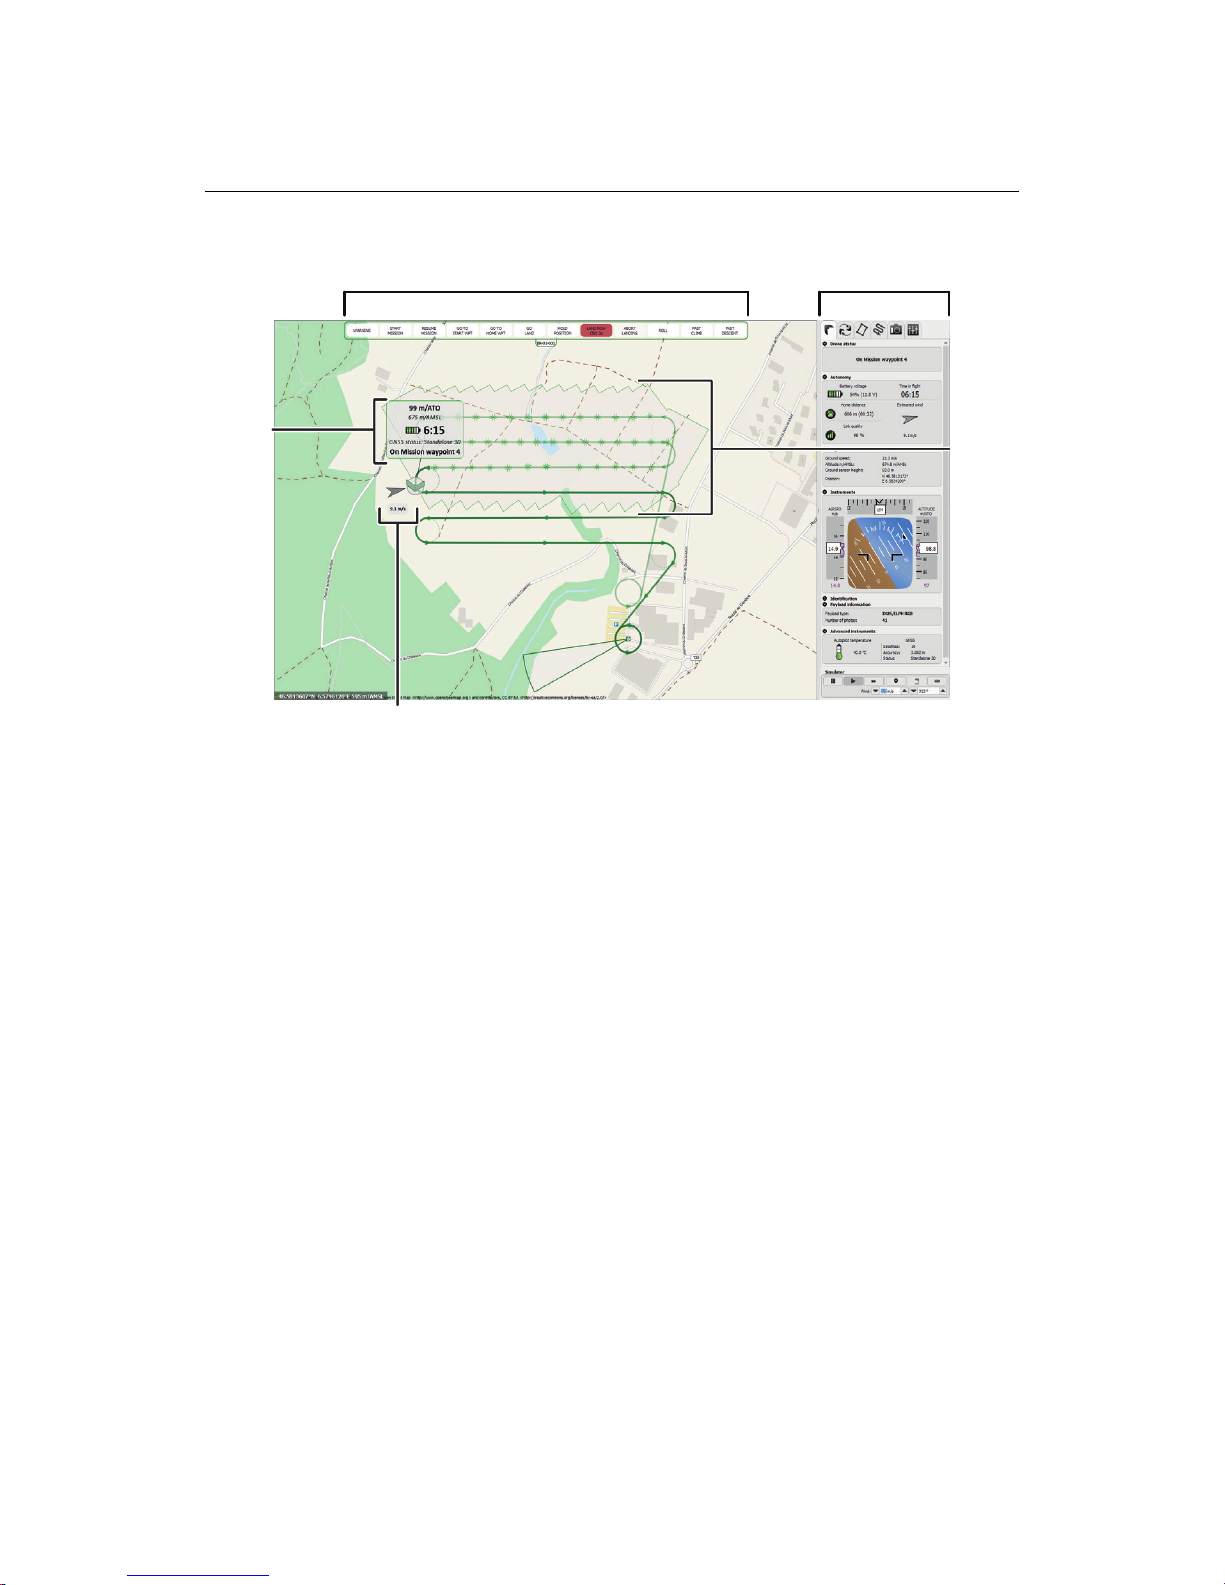
You can monitor andcontrol your drone whilein-flightthrough eMotion using the
Map Area and the Flight Monitoring tab in the Sidebar.
The Map Area displays the current position of your drone, updated live as the
drone executes its flight. A small arrow and infobox show thespeed and direction
of the wind as measured by the swinglet CAM. The Status Panel that follows the
position of the drone displays basic flight information including battery charge,
flight time and altitude, both above the take-off location (ATO) and above mean
sea-level (AMSL). This same information is reproduced in the Flight Monitoring
tab, along with other useful flight data .
39
Page 40
Quick start guide
Note: All waypoints, image locations and flight paths displayed in
eMotion are a reflection of the data contained within the drone autopilot. If at any point the connection between eMotion and the
drone is lost, the drone will by default continue its planned flight,
including the imaging mission and the selected automatic landing,
fully autonomously. If you would like the drone to return to the
Home waypoint instead of continuing its mission when it detects
a loss of connection you may set the appropriate parameter in the
Flight Parameters tab, as described in section ‘Flight Parameters tab’
on page 102.
During theMission phaseoftheflightthe swinglet CAM will automaticallytakepictures at pre-defined moments based on the parameters that were defined during
mission planning. The estimated area captured on the ground is displayed in the
form of a continuously-updating polygon in the Map Area.
Note: The swinglet CAM will not take a picture unless it is in the cor-
rect location and altitude. Some reasons for not taking an image are
strong head wind, large off-trackdistance orincorrect altitude. A corresponding message is displayed inthe Status Panel if a picture is not
taken.
At the top of the Map Area is the Control Bar, which can be used at any time to
send commands to your drone as well as to acknowledge warning and failure
messages if they occur. During a fully autonomous flight the swinglet CAM will
control its flight autonomously from take-off to landing and you do not need to
use any of the control buttons. They can however be useful in unexpected situations to temporarily hold position by pressing the ‘HOLD POSITION’ button or to
send the drone to the Home or Start waypoints with the ‘GO TO HOME WPT’ or ‘GO
TO START WPT’ buttons, respectively. Alternatively, you can direct your drone to
any location by right-clicking in the MapAreaand using the contextual menu. We
recommendyouuse the simulator to learn the effects of the buttons on the drone.
Detailed descriptions of the buttons and their effects on the drone are described
in section ‘Control Bar’ on page 76.
40
Page 41
Executing a flight
2.6 Landing
After finishing a mapping mission the drone will, by default¹², return to the Home
waypoint and automatically initiate a landing sequence. During a Circular landing the drone will land in a circle according to the process described in section
‘The setup phase of a flight’ on page 33.
Disconnect the battery from the drone before picking it up. We recommend you
immediately import the images and flight data after each flight (see section ‘Importing imagesand flight data’ on page 43) before putting the swinglet CAM back
in its case for storage. Remove the propeller if you don’t plan on using the
swinglet CAM for an extended period of time.
2.7 Potential in-flight errors
The drone can encounter twotypes of error messages whileflying: In-flight warnings and Critical failures. In-flight warnings typically indicate a dangerous situation such as a low battery or strong winds and typically result in a Security action
such as a return tothe Home waypoint. In-flightwarningsappearinblueoryellow
in the Flight Monitoring tab. Critical failuresoccur only when thedrone’s ability to
fly is severely compromised, suchas a loss ofGPS signals or an empty battery. The
situation will be displayed in redin theStatussection of the Flight Monitoringtab.
When a critical failure arises, the drone will immediately perform an emergency
landing.
Caution: We recommend that you familiarise yourself with the possible in-flight errors to have a better understanding of what happens
if they occur in the field. A full list of possible In-flight warnings and
Critical failures and the drone’s reaction to them is described in section ‘In-flight warnings’ on page 131 and section ‘Critical failures’ on
page 141.
¹² see section ‘Setup Phase tab’ on page 82 for information on changing the default behaviours of the
drone
41
Page 42
Quick start guide
Note: It is important to keep track of thelocation of the drone during
a Critical failure untilthe moment it reachesthe ground. Its position’s
coordinates can aid in finding it afterwards. Instructions on how to
find a lost drone can be found in section ‘Losing and locating your
swinglet CAM in the field’ on page 146.
42
Page 43
Processing image data
3 Processing image data
Goal of this section: In this section you will learn how to import im-
ages and flight data from your swinglet CAM and create basic mapping products directly in the field to gauge the quality of the images
that you gathered.
3.1 Importing images and flight data
The next step to creating mapping products, after completing a flight, is to import the raw images and log files to a computer. The swinglet CAM records flight
data onboard in a special Drone Flight Log file. The Drone Flight Log tracks important information throughouta flight, such as sensor data, locationand control
inputs. The file is required for assigning location information (geotags) to the images taken bythe drone. The file is also required andmust be sentto senseFly Ltd
in case an issue occurred during the flight¹³. A similar eMotion Flight Log file is
created within eMotion during a flight and serves as a backup in case the Drone
Flight Log file cannot be recovered.
eMotion features a Flight Data Manager to help you transfer and consolidate all
the data related to a mapping mission. Open the Flight Data Manager by clicking
on the Flight Data Manager icon when you load eMotion. Alternatively, click on
the button in the Toolbar and select ‘Flight Data Manager...’.
¹³ see section ‘Reporting a problem with your swinglet CAM’ on page 147
43
Page 44
Quick start guide
click OK
select Flight
Data Manager
Follow these steps to import data from the drone:
• Step 1 - Select a flight: If the flight was monitored from the computer
you are using to import images then the flight is saved within the local
database. Select the date that the flight took place. A list of flights (including number of images taken) from that date will appear in the combo
box, select the one you wish to import.
• Step 2 - Create a directory: Choose a directory name that uniquely iden-
tifies your flight (e.g. the date, the name of the area, etc.).
44
Page 45
Processing image data
connect USB cable
to autopilot
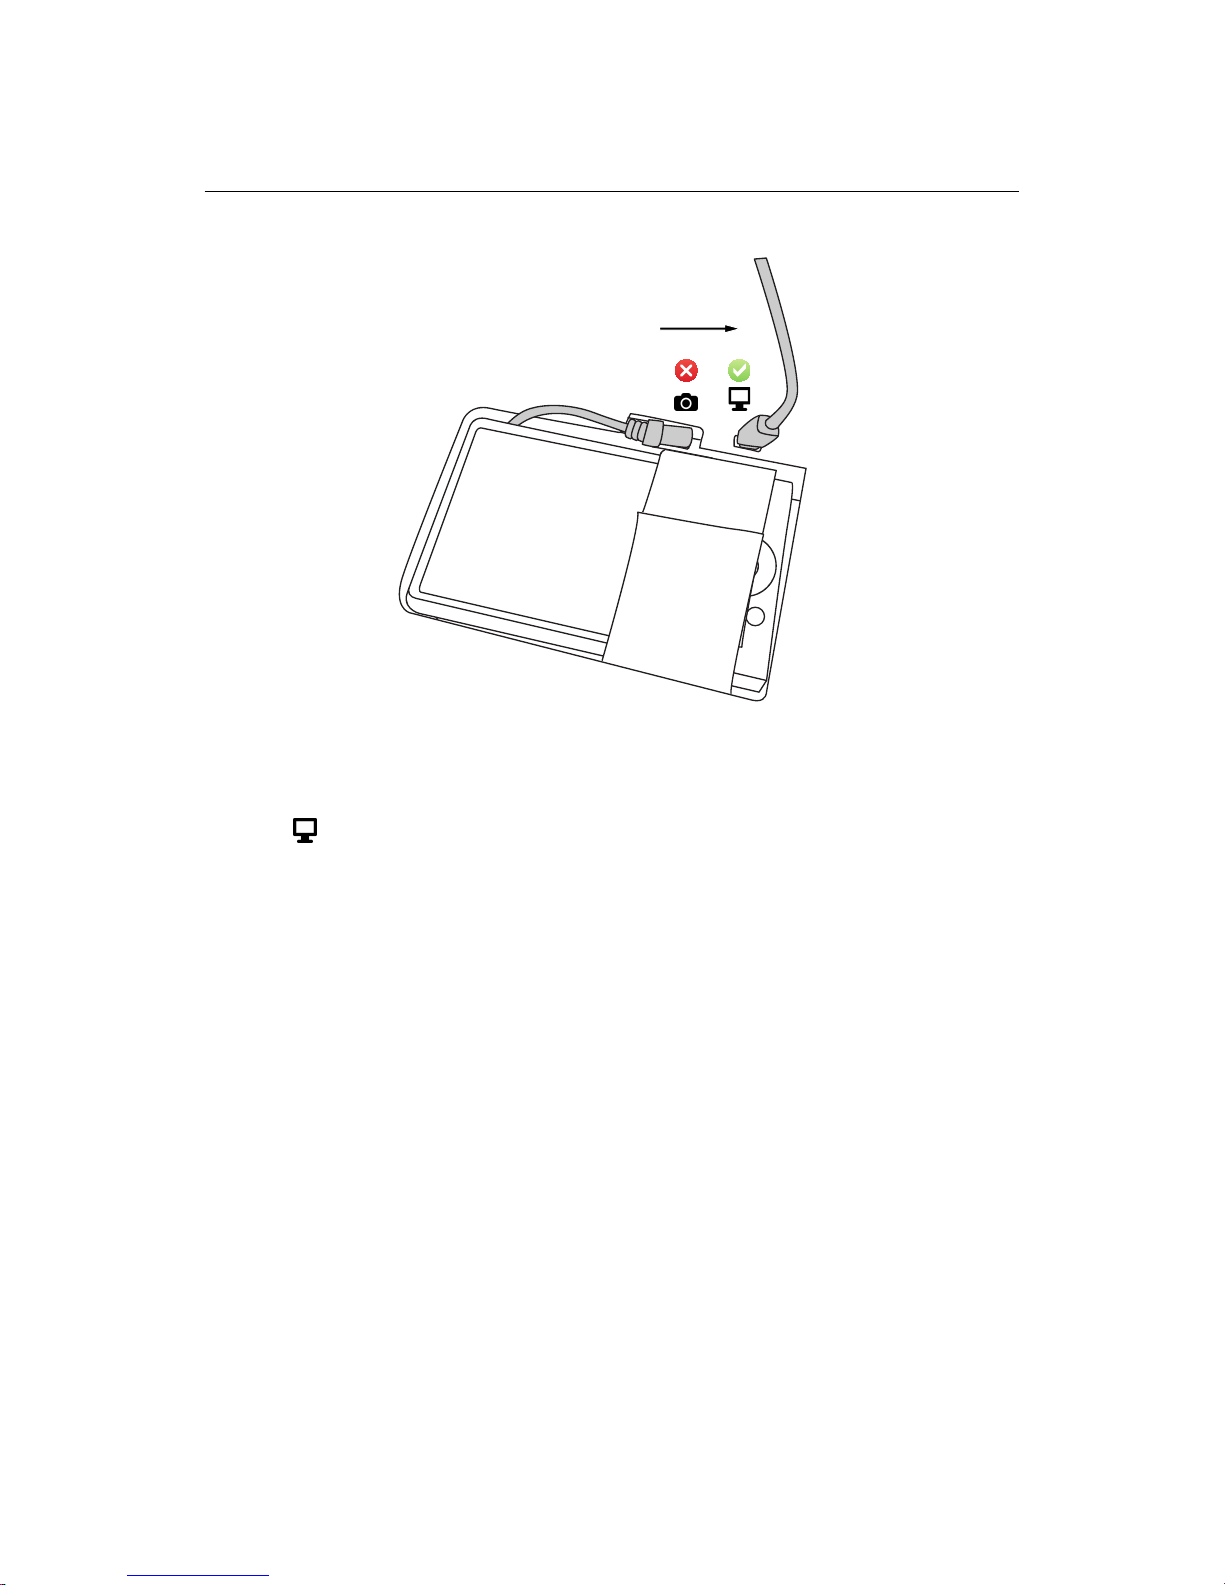
• Step 3 - Prepare data for import: To import the Drone Flight Log, con-
nect the supplied USB cable to the swinglet CAM’s autopilot, marked with
a icon. Connect the battery to the drone if it is not already connected.
The status LED will become white and a new storage drive will appear on
your computer.
To import images, remove the SD card from the camera, insert it into the
SD card reader of your computer and select ‘Import from SD-card reader’.
Alternatively, transfer the images from the camera by lifting it out of its
compartment just enoughto connecta USB cable to itand turnthe camera
on. Copy all the images into a temporary folder on your computer. Select
‘Import from a specific folder’ and choose the temporary folder.
• Step 4 - Import flight logs: Confirm that the Drone and eMotion Flight
Logs found by the Flight Data Manager are correct. You may select logs
manually if they are not correctly detected.
• Step 5 - Import images: Confirm that the images corresponding to your
flight were found and matched to the Drone Flight Log correctly.
45
Page 46
Quick start guide
• Step 6 - Select outputs: Choose the output actions to execute and files to
create. Geotagging images is necessary to create geoinfo, KML and Post-
flight Terra LT files.
• Step 7: You may now disconnect the drone. Eject the SD-card drive and the
drone drive before removing the SD-card and the USB cable, respectively.
Disconnect the battery and USB cable from the drone. Insert the SD-card
back into the camera, put it back properly into itscompartment and ensure
that it is turned off. Youcan now open the KML file in Google EarthTMor the
project in Postflight Terra LT for further processing.
3.2 In-field image quality check
Postflight Terra LT software¹⁴, available as a free download with the swinglet CAM
package, can be used to rapidly create a Quality Report directly in the field. The
Quality Report that is automaticallygenerated aswellas the orthomosaic provide
immediate feedback on the quality of the images gathered during your mission.
You can open a project for processing in Postflight Terra LT directly fromthe Flight
Data Manager after importing your data by clicking the ‘Open project in Terra’
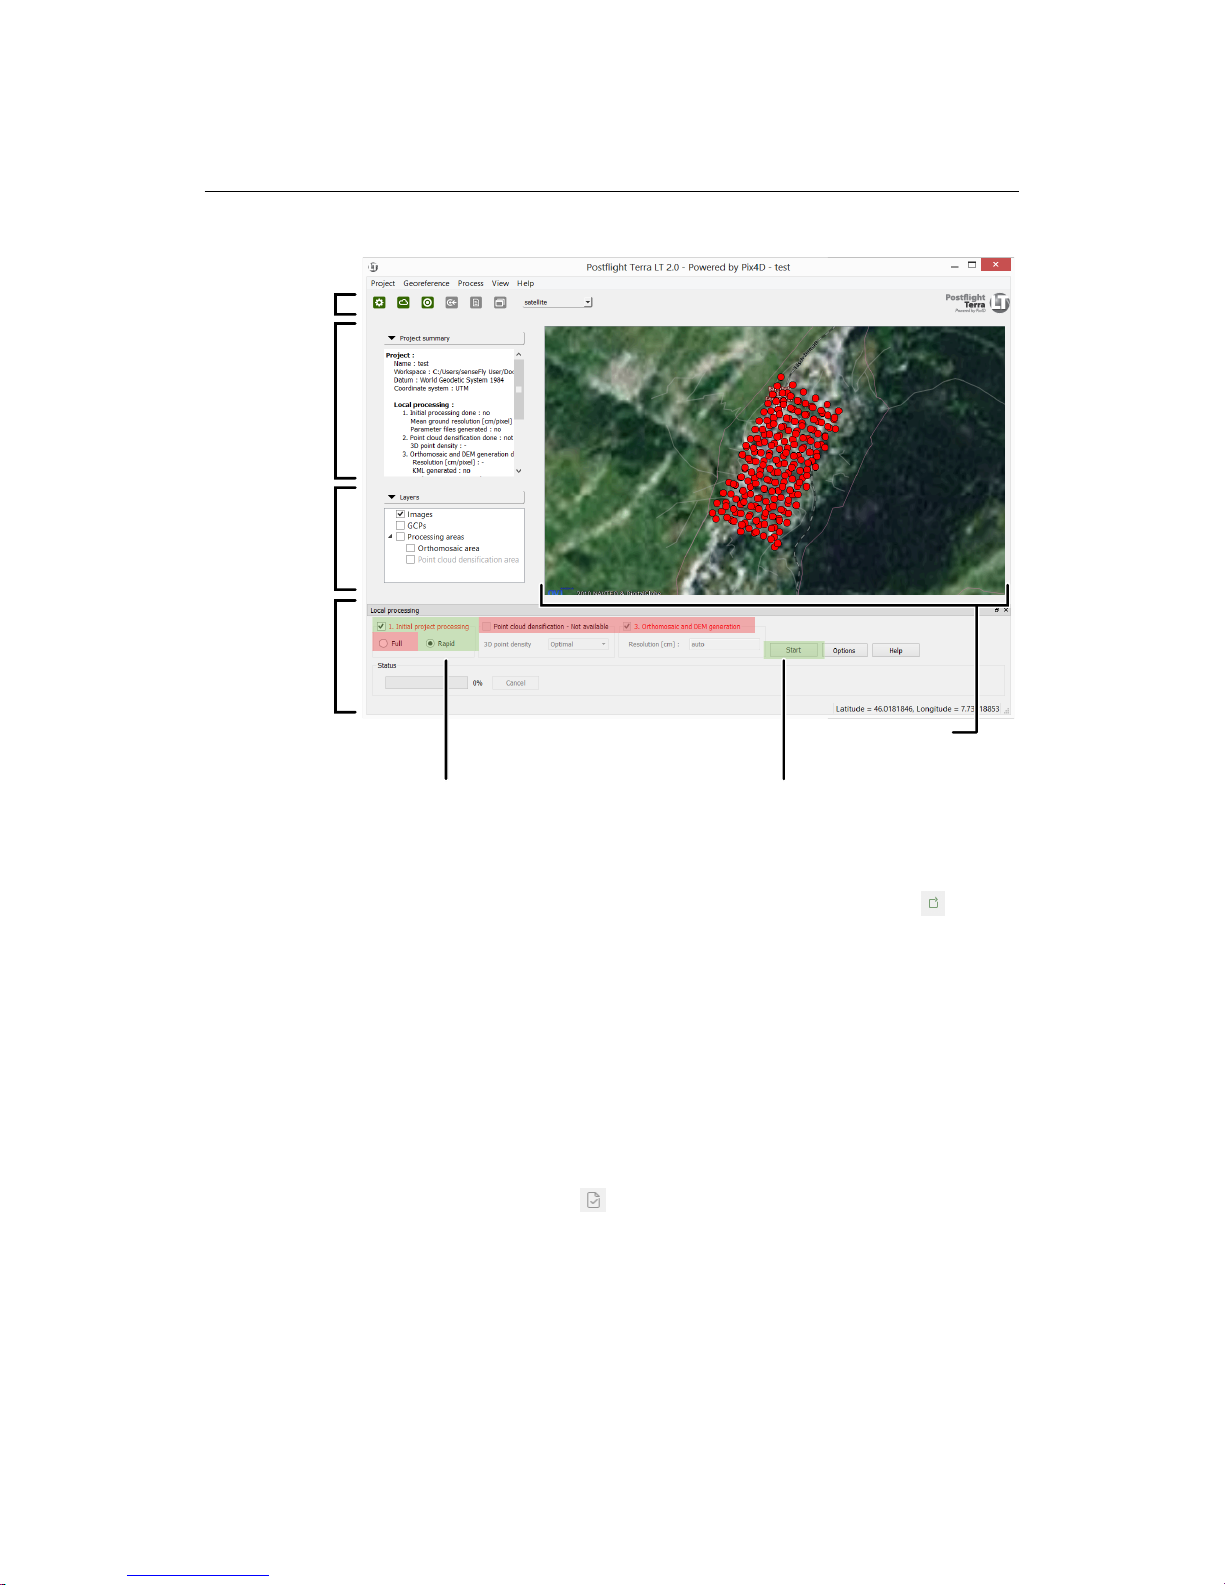
button. You will now see the main Postflight Terra LT window. The position of
your images will appear as red dots in the Map Area of Postflight Terra LT.
¹⁴ powered by Pix4D,see section ‘InstallingeMotion, Postflight TerraLT , and theground modemdrivers’
on page 16 for installation instructions
46
Page 47
Processing image data
Map Area
Top Toolbar
Project
Summary
Local
Processing
panel
Layers
Step 1: select ‘1. Initial project processing’, ‘Rapid’ Step 2: click ‘Start’
Automatic Reconstruction
Report generation
To create a Quality Report while in the fieldbring up the local processing panel by
selecting ‘Local processing’ from the ‘Process’ menu or by clicking the icon in
the Toolbar. Select only the ‘Initial project processing’ checkbox and the ‘Rapid’
button. If you wish to create a low-resolution orthomosaic while generating the
report, check the ‘Orthomosaic and DSM generation’ checkbox. Click ‘Start’ to
begin rapid processing.
Postflight Terra LT will now process the data and produce a report that includes
the overall completeness and georeference quality of the images taken during
your last mission. You may use this information to decide whether further imaging flights are required while you are still in the field. The quality report will be
displayed in a new window (click the icon in the Toolbar if it does not appear).
47
Page 48
Page 49
Part II
Advanced functionalities
Page 50
Advanced functionalities
4 Understanding aerial mapping with theswinglet CAM
Goal of this section: Aerial mapping using the swinglet CAM is de-
signed to be simple and fully automatic, requiring very little input
from the user. Understanding the basics of aerial navigation, however, can helpyou map more complex terrain and yieldhigher quality
results. Thissectionexplainsthebasicsof waypoint-based navigation
and the control strategies used by the drone for flight.
4.1 Waypoints and their properties
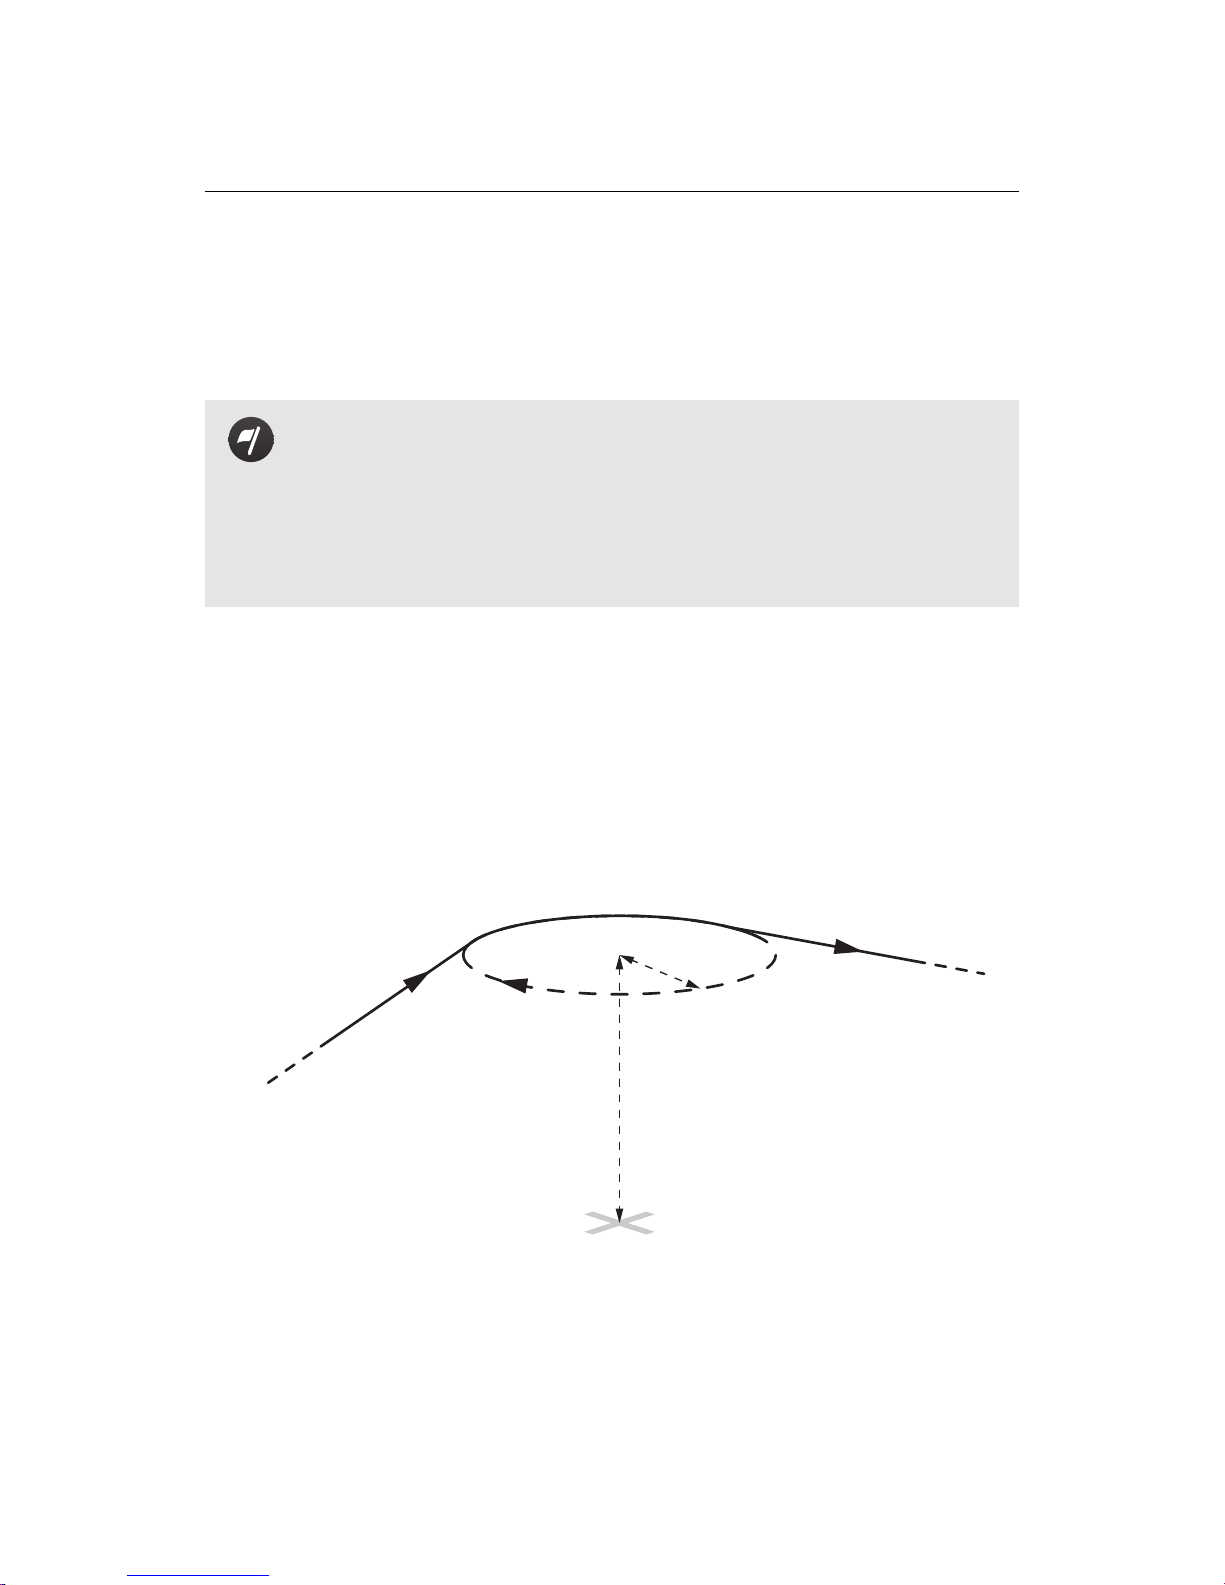
The swinglet CAM uses a flight plan consisting of a list of waypoints to navigate.
A waypoint essentially consists of a circle about a given position and information
that defines how the drone should behave when reaching them. The entire list
of waypoints is stored in the drone autopilot and can be remotely edited using
eMotion.
from previous
waypoint
to next
waypoint
Position (GPS coordinates)
Altitude:
Above Take-off location (m/ATO)
OR
Above Mean Sea Level (m/AMSL)
Radius
Direction
In eMotion every waypoint is defined by the following parameters:
• ID: Everymissionwaypointhas a unique ID,beginning at 1. The swinglet CAM
50
Page 51
Understanding aerial mapping with the swinglet CAM
can store up to 50 mission waypoints. Setup phase waypoints (Start and
Home) do not have an ID.
• Active: Indicates whether the waypoint is active or not. Deactivating a
waypoint by clicking the checkbox beside its ID will remove it fromthe current flight plan. Setup phase waypoints (Start and Home) cannot be deactivated.
• Current: A status that indicates if the waypoint is currently being circled
or navigated toward (indicated by > < around the waypoint’s ID). Only one
waypoint is marked Current at a time.
• Change altitude: This parameter defines the way the drone transitions to
the altitude of the current waypoint.
– During transit: The drone willfly in the direction of the current way-
pointwhilesimultaneouslychanging altitude by climbing or descending in a linear fashion. If the required climb or descent rate is beyond physical limits, the drone will reach the destination and keep
climbing/descending around the destination waypoint. This is typically used to achieve the best efficiency when the altitude between
waypoints is not constrained.
– Before transit: The drone will first climb or descend at its current
position until it reachesthealtitudeofthecurrentwaypoint, and then
fly in the direction of thewaypoint at its altitude. This is typicallyused
for 3D mapping.
– Keep highest: The drone will first determine whether its current al-
titude or the current waypoint’s altitude is highest. If the drone’s current altitude is highest, it will first fly towards the waypoint and then
descent to the waypoint’s altitude in a circular fashion. If the current
waypoint’s altitude is highest, the drone will begin by climbing at its
current position until it reaches the waypoint’s altitude and then fly
towards the waypoint. This is typically useful to avoid hitting the terrain in mountainouslandscapes and, in particular, forthe Home waypoint when the mission altitude is below the take-off location.
51
Page 52
Advanced functionalities
• Altitude: The altitude of the waypoint above the altitude reference. The
waypoint is considered‘reached’ only when the drone starts circling about
it at the waypoint’s altitude.
• Altitude reference: The reference point of theAltitude value. When set to
m/ATO, the Altitude value is an Above Take-off (ATO) altitude. When set to
m/AMSL,theAltitudevalueisa Above Mean Sea Level (AMSL).Thealtitudes
of Setup phase waypoints (Start and Home) are always set to m/ATO.
• Turndirection: The direction with which the drone circles aroundtheway-
point (clockwise or counter-clockwise).
• Radius: The distance at which the drone circles around the waypoint.
Note: The swinglet CAM has a limited turning radius. Setting this pa-
rameter lower than 20 m may cause thedroneto significantly deviate
from its desired flight path.
• Auto-next: Indicates whether the drone should remain on the waypoint
upon reaching it (until a new command is received) or automatically continue to the next active waypoint.
• Action: The action (if any) to be performed upon reaching the waypoint.
Supported actions include starting and stopping Continuousphotomode¹⁵.
Setup phase parameters (Start and Home) do not have associated Actions.
• Position (coordinates): The precise latitude and longitude of the centre
of the waypoint.
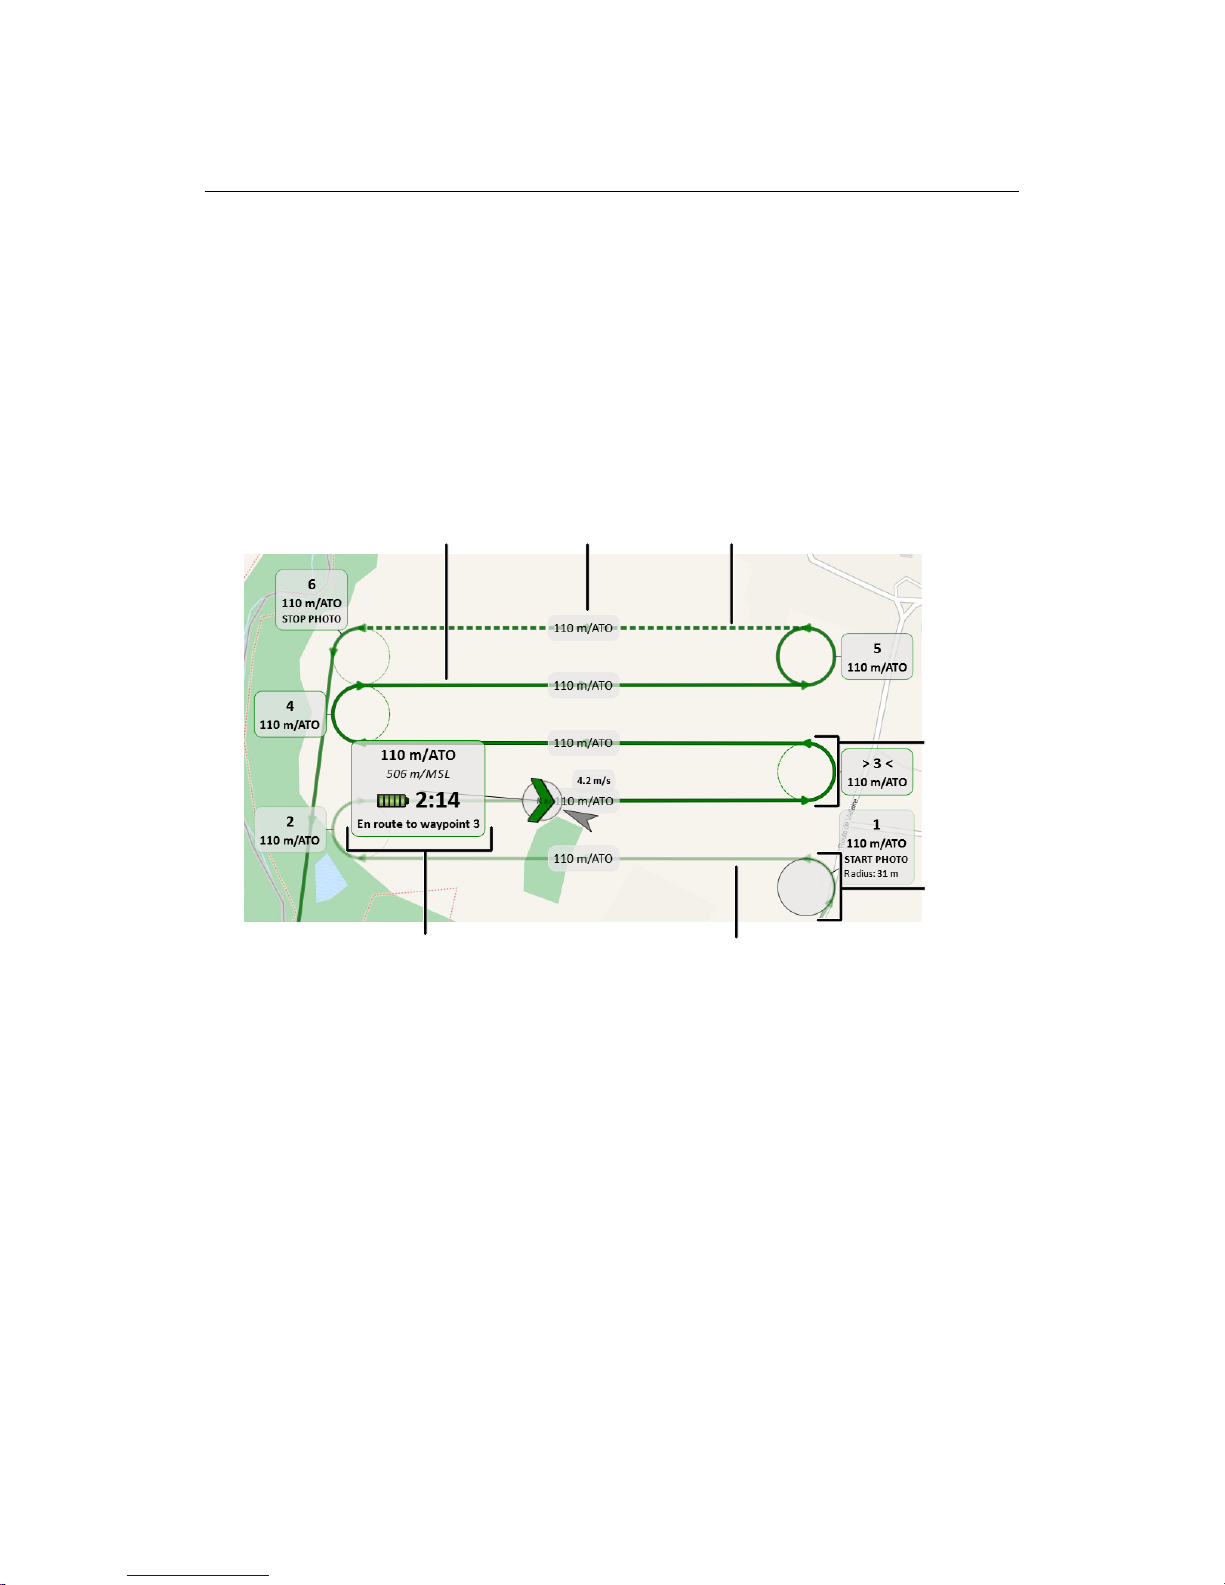
Waypoints are represented in the Map Area as circles with their actual radius and
an arrow to indicate their direction. The flight path of the drone around and in
between waypoints is drawn as a line of varying opacity; the path ahead of the
drone’s current position is dark, becoming lighter the further itis from the current
position in the flight plan. The path already traversed is a uniform light colour.
¹⁵ see section ‘Camera tab’ on page 97
52
Page 53
Understanding aerial mapping with the swinglet CAM
If a waypoint’s Auto-next parameter is disabled, the path directly after it will be
dashed, indicating that a command must be sent for the flight to continue.
Clicking a waypoint in the Map Area will display its characteristics (waypoint ID
for mission waypoints or name for setup waypoints, altitude, radius and action)
and will select it for modification. It will also activate the Mission Waypoints tab
and highlight the selected waypoint.
Current
waypoint
Selected
waypoint
Traversed flight path
Future
flight path
Inactive
flight path
Current status
Flight path
altitude
You can modify the waypoint’s parameters directly in the Map Area using your
mouse using the following actions:
• Position: Change the position by left-clicking on the waypoint and drag-
ging it around on the map. By default the waypoint snaps to a position inline with the current flight lines before and after the waypoint. Hold down
the ‘Alt’ button while dragging to disable the snapping feature.
• Turn direction: Hold down the ‘Shift’ button while left-clicking on a way-
point to toggle its turn direction.
• Radius: Modify the radius by left-clicking on the waypoint’s perimeter and
dragging it.
53
Page 54
Advanced functionalities
• Altitude: Hold down the ‘Ctrl’ button while left-clicking on the waypoint
and moving the mouse up or down to increase or decrease the altitude of
the waypoint, respectively.
• Createnew waypoint: Right-click anywhere in the Map Areathatdoesnot
contain a symbol to bring up the context menu, then select ‘Add waypoint
here’ to add a new waypoint.
• Context menu: Right-click on a waypoint to bring up the context menu.
You can then select the following options:
– Go to: Select while thedrone is in flightto make this the current des-
tination waypoint.
– Auto-next: Toggle the Auto-next parameter of the waypoint.
– Reverse turn direction: Toggle the Turn direction parameter of the
waypoint.
– Change altitude: Set the transition behaviour of the drone when
flying towards the selected waypoint.
– Remove waypoint: Remove the selected waypoint.
Any modification will be sent directly to the drone to update its onboard waypoint
list. If the message is not acknowledged by the drone (for example due to a temporary loss of communication link), the waypoint will move back to its previous
position on the map to accurately reflect the current waypoint list status within
the drone’s autopilot.
Note: Modification of flight plan parameters can cause the drone to
react in unexpected ways. In particular, the drone may have trouble
following its flight path when the radius is set very low or if there
is high wind. We highly encourage you to test your entire flight plan
using the simulator to get familiarwith the drone’s behaviours before
going out into the field.
54
Page 55
Understanding aerial mapping with the swinglet CAM
4.2 Advanced polygonal mission area
Themission areadefinestheareaofinterestwhere the swinglet CAM will take photos. It appears as a grey rectangle when you select the ‘Mission planning’ tab and
to calculate the flight plan of the drone. For many cases the rectangular-shaped
mission area provides the simplest way to quickly create a flight plan. It can be
modified as described in section ‘The mission phase of a flight’ on page 20.
For more complex areas eMotion has the option of using polygonal-shaped missions areas. Begin by converting a rectangular area into a polygonal area by setting the ‘Mission area’type to ‘Polygonal’ in the ‘Mission planning’ tab or by rightclicking on the area and selecting ‘Convert to polygon’.
A polygonal mission area is setslightlydifferentlythan a rectangular mission area:
• The edges of the rectangle now become vertices of the polygon. Left-click
on a vertex to drag and reposition the vertex.
• Left-click and drag anywhere on the edge of the polygon to create a new
vertex and reposition it.
• Right-click on vertex and select ‘Remove vertex’ to remove a vertex. Alternatively, hold down the ‘Ctrl’ button and left-click on a vertex to remove
it.
• Left-click and drag on the dark-grey area within the polygon to reposition
the entire polygon.
• Left-click and drag the circle on the corner of the light-grey rectangle surrounding the polygon to rotate the direction of the resulting flight lines.
You may also set a polygonal mission area directly from a KML file containing a
polygon, such as those created by Google EarthTM. Simply click on the icon in
the ‘Mission planning’ tab, select ‘Load mission area from KML file’ and choose a
KML file that contains the desired polygon.
55
Page 56
Advanced functionalities
4.3 3D mission planning using elevation data
eMotion has the ability to take into account elevation data to set the altitude of
mission waypoints and the resulting flight lines of a mapping mission. This not
only improves the resulting ground resolution but also increases mission safety
(particularly in uneven terrain) by keeping amoreevenheight between the drone
and the ground.
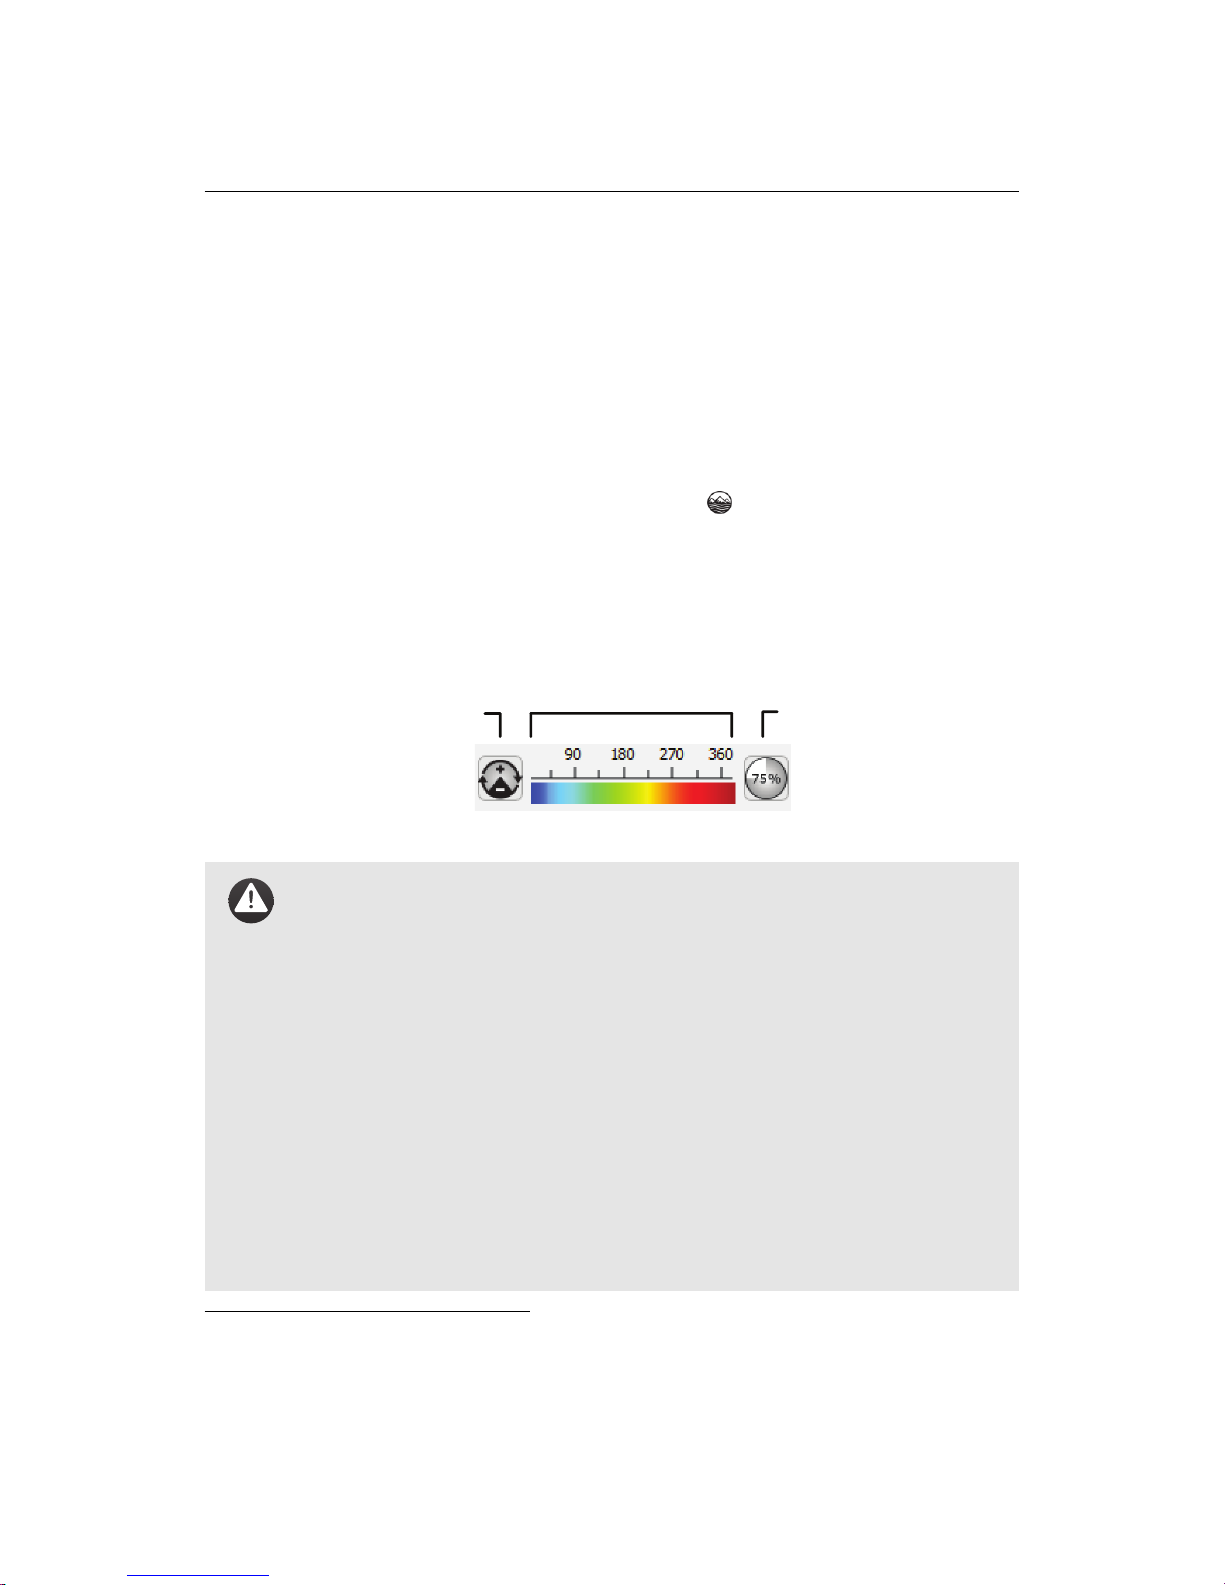
You can display elevation data by clicking on the button in the Toolbar. eMo-
tion’s default Improved SRTM elevation data will be downloaded as tiles from
senseFly Ltd servers and overlaid above the map as a colourmap¹⁶. You can adjust the scale and opacity of the colourmap by using the associated buttons in
the bottom-right corner of the Map Area.
Elevation colourmap
Change opacityAuto-adjust colormap
Caution: eMotion’s default Improved SRTM elevation data uses a 3
arc-second (approx. 90 m resolution) digital elevation model derived
from the SRTM (Shuttle Radar Topography Mission) dataset version
2.1 combined with other data sources (ASTER GDEM, SRTM30, cartographic data, etc.). This data covers nearly all emerged land except
the territories below 56◦S latitude and the territory of the Russian
Federation above 60◦N latitude. This data may contain inaccuracies
of several meters, and does not contain data on obstacles such as
buildings or trees. We highly recommend that you check your flight
plan thoroughly in Google EarthTMand ensure sufficient clearance between the flight plan and the ground. SenseFly Ltd provides no guarantee regarding the accuracy of the elevation data and it is the operator’s sole responsibility toensure a safe flight trajectory and altitude.
¹⁶ eMotion must be connected to the internet. Once downloaded, elevation tiles are cached and can
then be used off-line.
56
Page 57
Understanding aerial mapping with the swinglet CAM
Activate the 3D mission planning feature by selecting the ‘Use elevation data to
set absolutewaypointaltitudes’ parameter inthe‘MissionPlanning’tab. Elevation
data is used to adjust every mission waypoint altitude as follows:
1. The flight planneruses elevation data tofind the maximalterrain elevation
under the current waypoint, the previous waypoint and the flight line that
connects the two.
2. This maximum value is increased by the target altitude value, and theresult
is set as the altitude of the current waypoint.
The altitude of every waypoint can always be manually adjusted in the Mission
Waypoints tab. By default, the ‘Change altitude’ parameter for the first mission
waypoint is set to ‘Keep highest’. For all other mission waypoints the ‘Change altitude’ parameter is set to ‘Before transit’ so that the drone climbs or descends to
the altitude of the next waypoint (and thus the next flight line) before transiting
and taking pictures.
It is important to understand that even if each flight line can have a different altitude, the altitude is constant along a given flight line. If the terrain altitude is
uneven along a flight line, the resulting imagery will have varying ground resolution and overlap. When the mission planner computes the altitudes of flight lines
it tries to ensure that the required amount of overlap is achieved, possibly leading to a lower ground resolution in some areas. During flight planning the range
of ground resolution computed by the mission planner is displayed. For optimal
results, it is best to set the orientation of the flight lines as parallel as possible to
the terrain’s contour lines.
One way to increase the resolution and accuracy of the elevation data is to fly a
first mission at high altitude and then create a dataset using Postflight Terra LT.
You can then automatically import the data into eMotion by selecting ‘Send DSM
to eMotion’ from the ‘Process’ menu within Postflight Terra LT. The dataset can
then be enabled using the menu in the Toolbar. eMotion will use this custom
dataset (wherever it is available) to set waypoint altitudes instead of its default
Improved SRTM elevation data.
57
Page 58
Advanced functionalities
Note: It is recommended to visually compare imported elevation
datasets with the default Improved SRTM elevation layer of eMotion
in order to detect possible mismatches. This comparison should be
done with a colourmap opacity value of 100%.
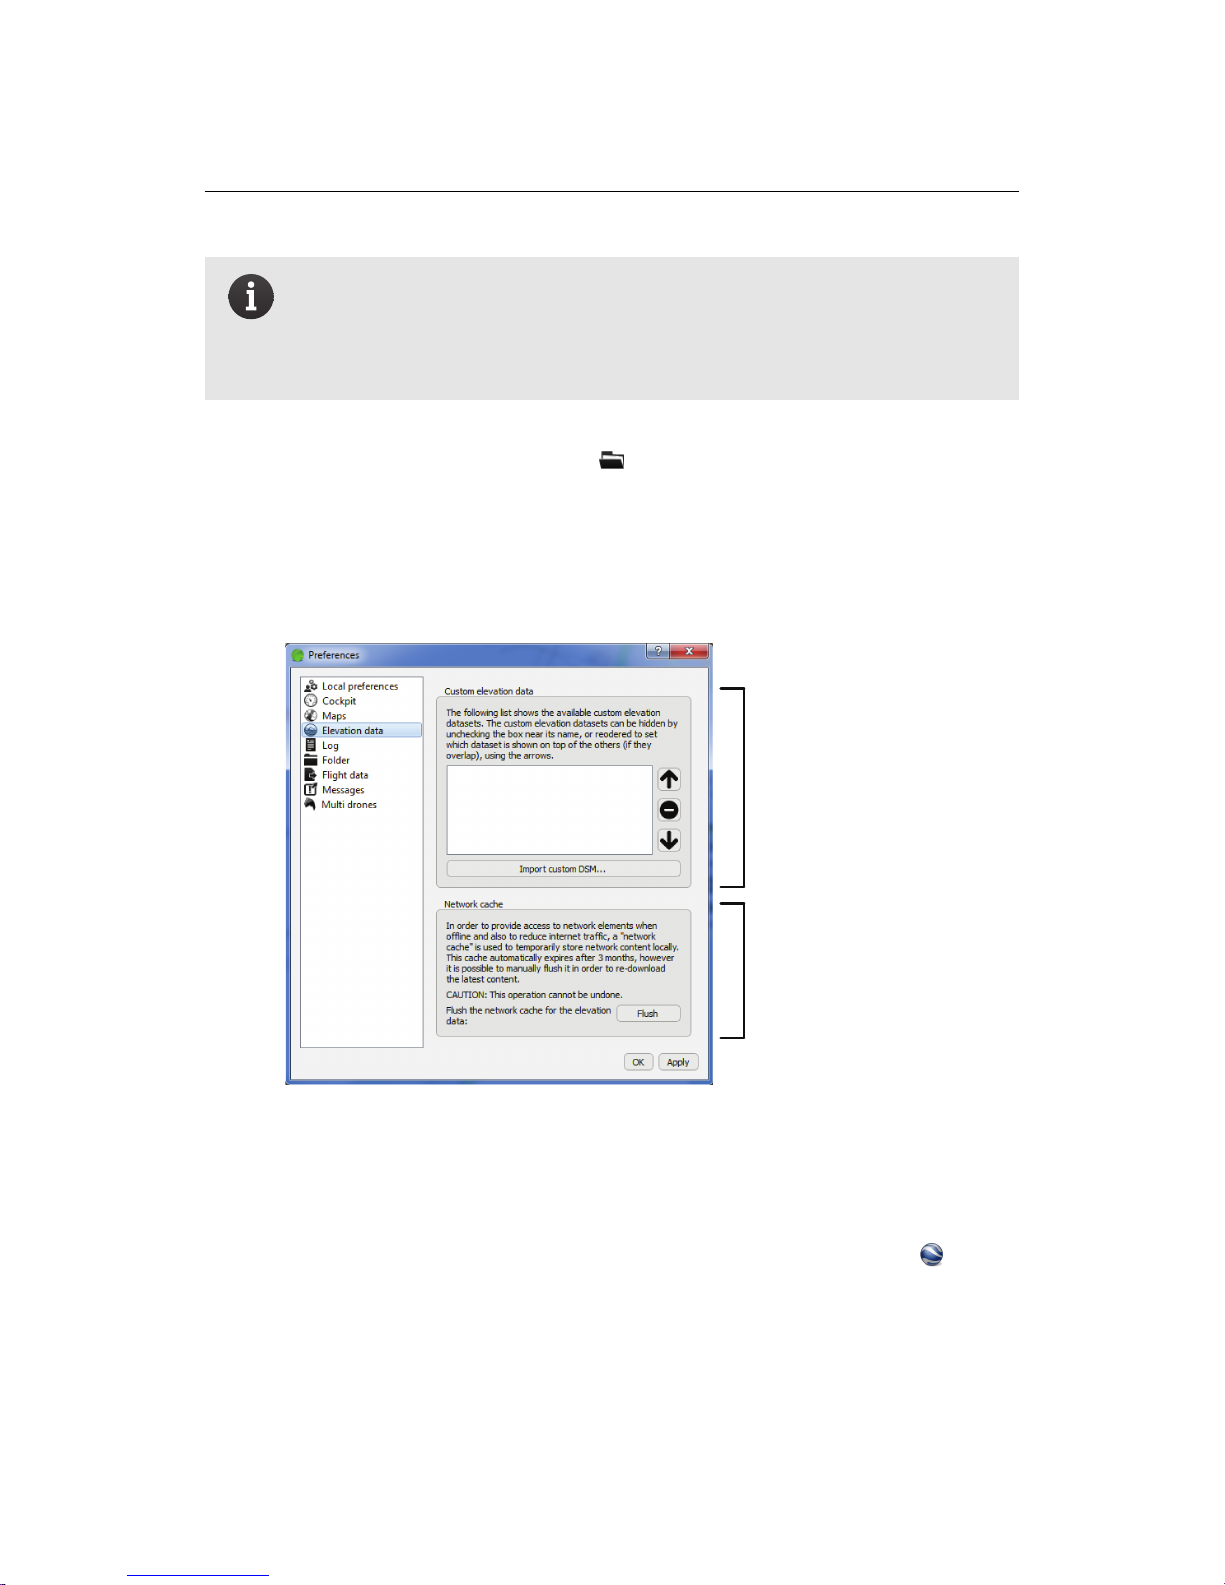
More advanced controls of imported datasets are available in the ‘Elevation data’
panel of the Preferences pane of the menu. From this panel you can add,
remove, activate/deactivate or reorder overlays. eMotion uses the top-most elevation data layer to calculate altitude for each waypoint and flight line, with
eMotion’s default Improved SRTM elevation dataset always considered the bottom layer.
Custom elevation
data
Network cache
4.4 Flight visualization in Google Earth
TM
eMotion includes an interface with Google EarthTMto help with flight plan verifi-
cation and visualization, particularly in uneven terrain. Clicking on the button
in the Toolbar will open Google EarthTMand zoom to the current position of the
drone. The current position of drone, its planned trajectory, the working area circle and all waypoints currently uploaded to the drone (including Take-Off, Start
58
Page 59
Understanding aerial mapping with the swinglet CAM
and Home) are displayed within Google EarthTM. Any changes to waypoints or
flight parameters within eMotion are updated accordingly within Google EarthTM.
The interface withGoogle EarthTMis particularly useful to checkthe drone’s trajectory with respect to obstacles in the area¹⁷. The flight plan is projected onto the
ground in a darker colour, giving you an idea of the distance between the flight
path and the ground. If you connect to a simulated drone you can simulate the
entire flight and follow the drone within Google EarthTM.
Note: To use this feature Google EarthTMhas to be installed on the
ground station PC, as described in section ‘Installing eMotion, Post-
flight Terra LT , and the ground modem drivers’ on page 16. We recommend to use the latest version of the Google EarthTMsoftware.
Caution: A flight trajectory visualized in Google EarthTMrepresents
the planned trajectory. Thereal flighttrajectory can be different from
the planned due to flight conditions such as strong wind.
Caution: The terrain data within Google EarthTM, including hills and
buildings, may contain significant errors. When planning flights over
uneven terrain be sure to keep sufficient distance between the flight
plan and the terrain.
¹⁷ While checking flight plans in Google EarthTMis a good safety practice, senseFly Ltd provides no
guarantee regarding the accuracy and completeness of the Google EarthTMterrain model.
59
Page 60
Advanced functionalities
4.5 Autonomous controller and modes of flight
Idle
(on ground)
Take-off
Circle
Start Waypoint
Perform
Mission
Circular Landing
Switch On
after a few seconds
on ground
shake 3x
and release
after climbing
to take-off
transition height
automatically after
2 complete circles
if landing has
been requested
if ‘Wait on Start
waypoint after
take-off’ is
enabled
if ‘Go to start waypoint
after mission’ is enabled
when mission is completed
Circle
Home Waypoint
Hold
Position
if ‘Restart mission
after mission’
is enabled
Emergency
Landing
Full
Manual
Assisted
Manual
Autonomous operation modes
Manual and emergency modes
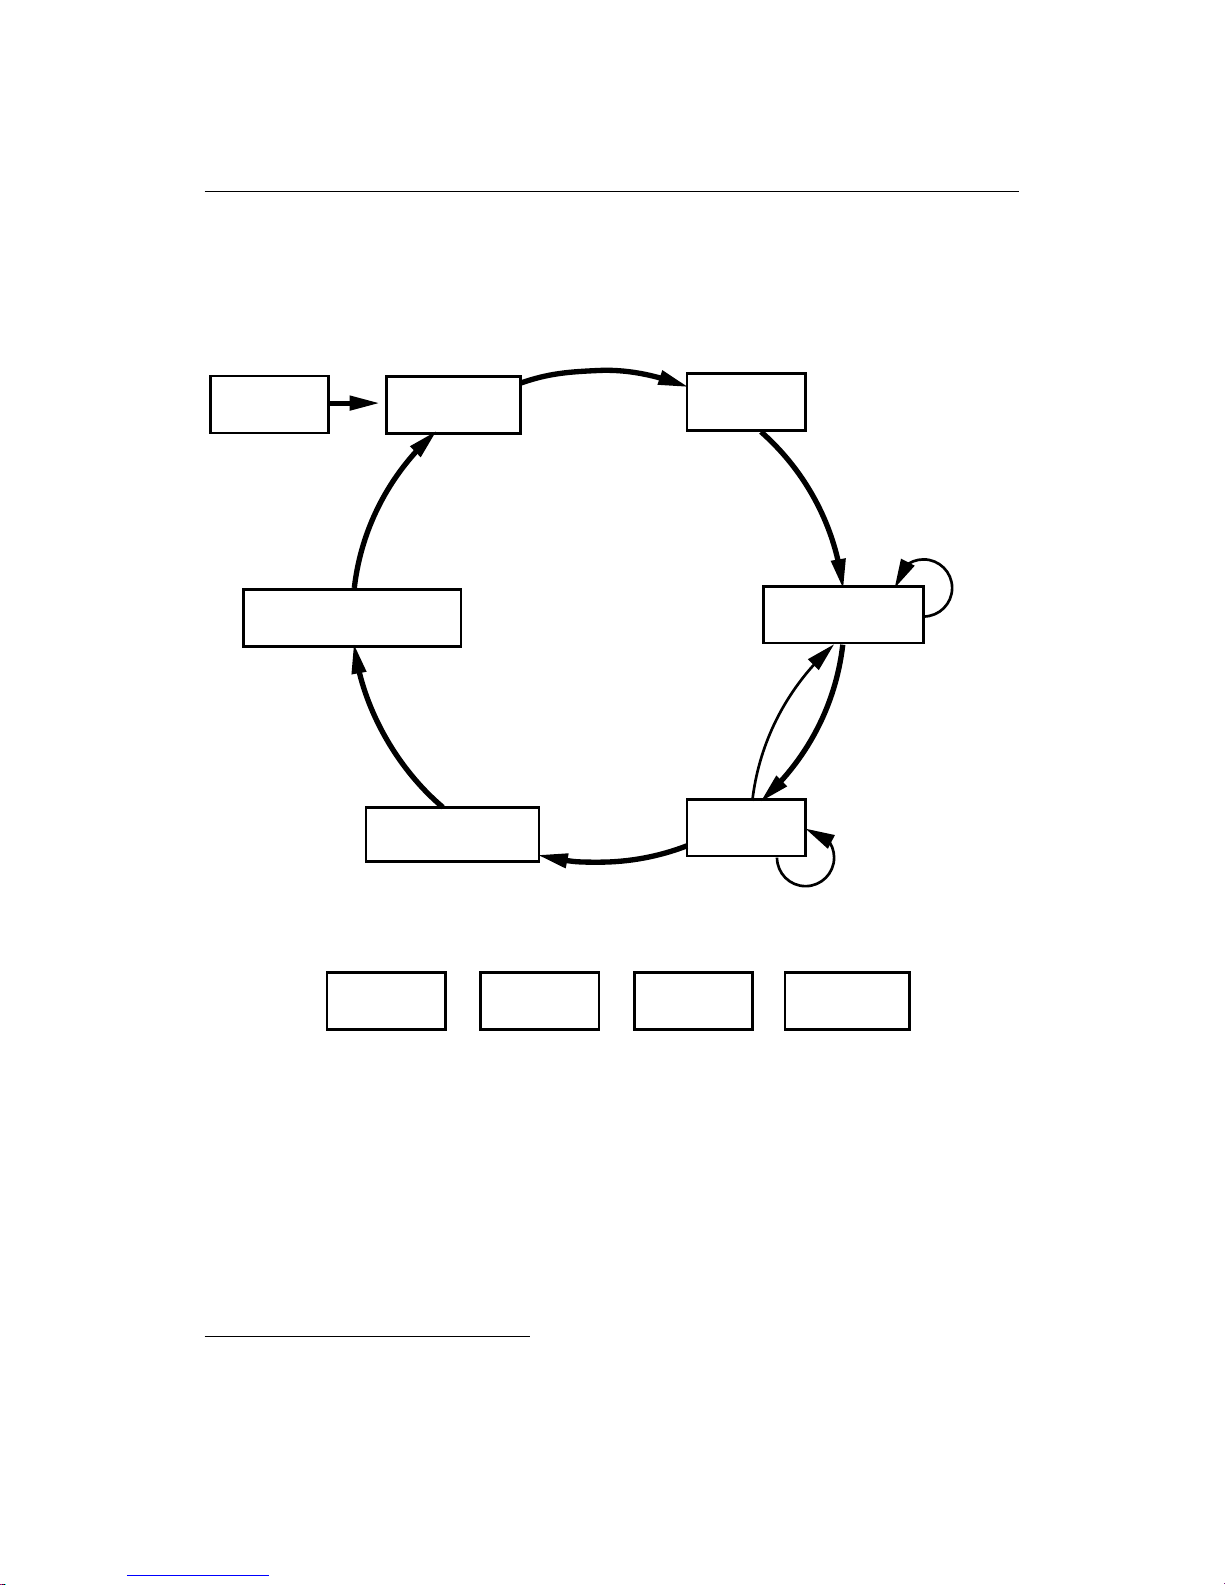
During a typical flight the autonomous controller on the swinglet CAM will switch
between various modes depending on its flight plan and the commands that it
receives from the Control Bar¹⁸. The controller changes between modes during a
typical mission as shown in the figure above, and as described in more detail in
the following list:
• After being switched on and running pre-flight checks the drone will enter
Idle mode until it is ready to be launched. Shaking the drone back and forth
¹⁸ see section ‘Control Bar’ on page 76 for details on the Control Bar
60
Page 61
Understanding aerial mapping with the swinglet CAM
three times initiates the take-off procedure¹⁹ and changes to the Take-off
mode.
• After take-off the drone climbs with level wings²⁰, gaining altitude until it
reachesthe take-off transition altitude, by default 20 m²¹ above the take-off
location. At this point the drone heads for the Start waypoint and changes
to Circle Start Waypoint mode.
• Once it reaches the Start waypoint, the drone circles the waypoint several
times to estimate the strength of the wind. Once itcalculates the estimated
wind the drone either:
– heads towards the first mission waypoint, if ‘Start mission’ isselected
in the ‘After take-off’ panel of the Setup Phase tab, and changes to
Perform Mission mode.
– continues circling the Start waypoint until a command is received
from the Control Bar (typically a ‘START MISSION’ command that is
sent once a flight plan is finalized).
• While in Perform Mission mode the drone flies betweenallenabled mission
waypoints, taking images of the ground below. Once it reaches the final
mission waypoint the drone either:
– heads towards the Home waypoint, if ‘Land’ or ‘Go to Home way-
point’ is selected in the ‘After mission’ panel of the Setup Phase tab,
and changes to Circle Home Waypoint mode.
– heads towards the Start waypoint, if‘Goto Start waypoint’ isselected
in the ‘After mission’ panel of the Setup Phase tab, and changes to
Circle Start Waypoint mode.
– heads towards the first mission waypoint, if ‘Restart mission’ is se-
lected in the ‘Aftermission’panel of theSetup Phase tab, and remains
in Perform Mission mode.
¹⁹ as described in section ‘Take-off’ on page 35
²⁰ or in a given direction when using the Directional take-off feature described in section ‘Setup Phase
tab’ on page 82
²¹ see section ‘Flight Parameters tab’ on page 102 for details on changing this altitude
61
Page 62
Advanced functionalities
• Once it reaches the Home waypoint (if in Circle Home Waypointmode) the
drone will either:
– begin a Circular landing procedure and change to Circular Landing
mode, if ‘Land’is selected inthe ‘After mission’ listof the Setup Phase
tab.
– circlestheHome waypoint and remains inCircleHome Waypointmode
until a command is sent.
• After completing a landing procedure and detecting thatit hassuccessfully
landed, the drone changes to Idle mode.
• Turningon the remote control and setting the autopilot switch to ‘manual’
will cause the drone to enter either Assisted Manual or Full Manual mode,
depending on the setting in the Flight Parameters tab²². Turning off the
remote control or setting the autopilot switchto ‘automatic’ will return the
drone to its previous mode.
• Clicking the ‘HOLD POSITION’ button in the Control Bar at any time will
cause the drone to start circling its current position and change to Hold
Position mode until it receives anew command from the Control Bar. Alternatively, right-clicking in the Map Area and selecting ‘Hold here’ will direct
the drone towards the selected position and then circle around that position in Hold Position mode. This mode is also enabled automatically after
certain In-flight warning or Critical failure conditions²³.
• Clicking the ‘LAND NOW’ button in the Control Bar three timesin quicksuccession will cause the drone to initiate a Circular landing procedure at its
current location with its motor disabled and change to Emergency Landing mode.
²² see section ‘Manual control of the swinglet CAM’ on page 106 for information on the various manual
control modes
²³ see section ‘Troubleshooting’ on page 126 for a full list of In-flight warning and Critical failure con-
ditions and the subsequent reactions of the drone
62
Page 63
Understanding aerial mapping with the swinglet CAM
4.6 Flying multiple drones at the same time
Operating multiple drones at the same time enables the coverage of larger areas
in a shorter amount of time. This can be useful when the mission time must be
kept short, for example because of varying lighting conditions. To enable multidrone operation eMotion provides the following:
• When more than one drone is connected at a time, a dedicated interface
called the Multi-drone panel is displayed to monitoreach droneand switch
between them.
• Anumberofsettingsare offered tokeeprelevantflight configurations(such
astheStart andHomewaypoint)synchronised between all connected drones.
• Missions that require more than one flight can be automatically split and
uploaded individually among all connected drones.
• A new Control Bar appearsat the bottom ofthe Map Area. Commands sent
using the buttonsin this Control Bar, such as‘START MISSION’ or ‘GO LAND,’
are sent to all the drones currently connected to your computer.
• Collision avoidance is provided by eMotion²⁴. This is done by automatically
changingthealtitudeofthe StartandHomewaypointsfor each drone inorder to separate them. Also, the drones are automatically put on hold when
there is a collision risk during the mission.
When connecting to more than one drone at a time (real or simulated), a dedicated Multi-drone Panel is displayed next to the Sidebar. Each drone is displayed
with its name, battery level and status and can beselected. The rest of the Sidebar
and its various tabs are associated to the currently selected drone, as indicated
by the colour of the frame. The multi-drone interface also displays the relative
altitude of all drones with respect to the selected drone. Since this is a relative
altitude, a value close to 0 m means that a drone is at the same altitude as the
currently selected drone. Right-clicking on a drone’s tab in the Multi-drone Panel
allows you to disconnect the drone or change its colour.
²⁴ if the option is selected in the Multi-drones preference pane
63
Page 64
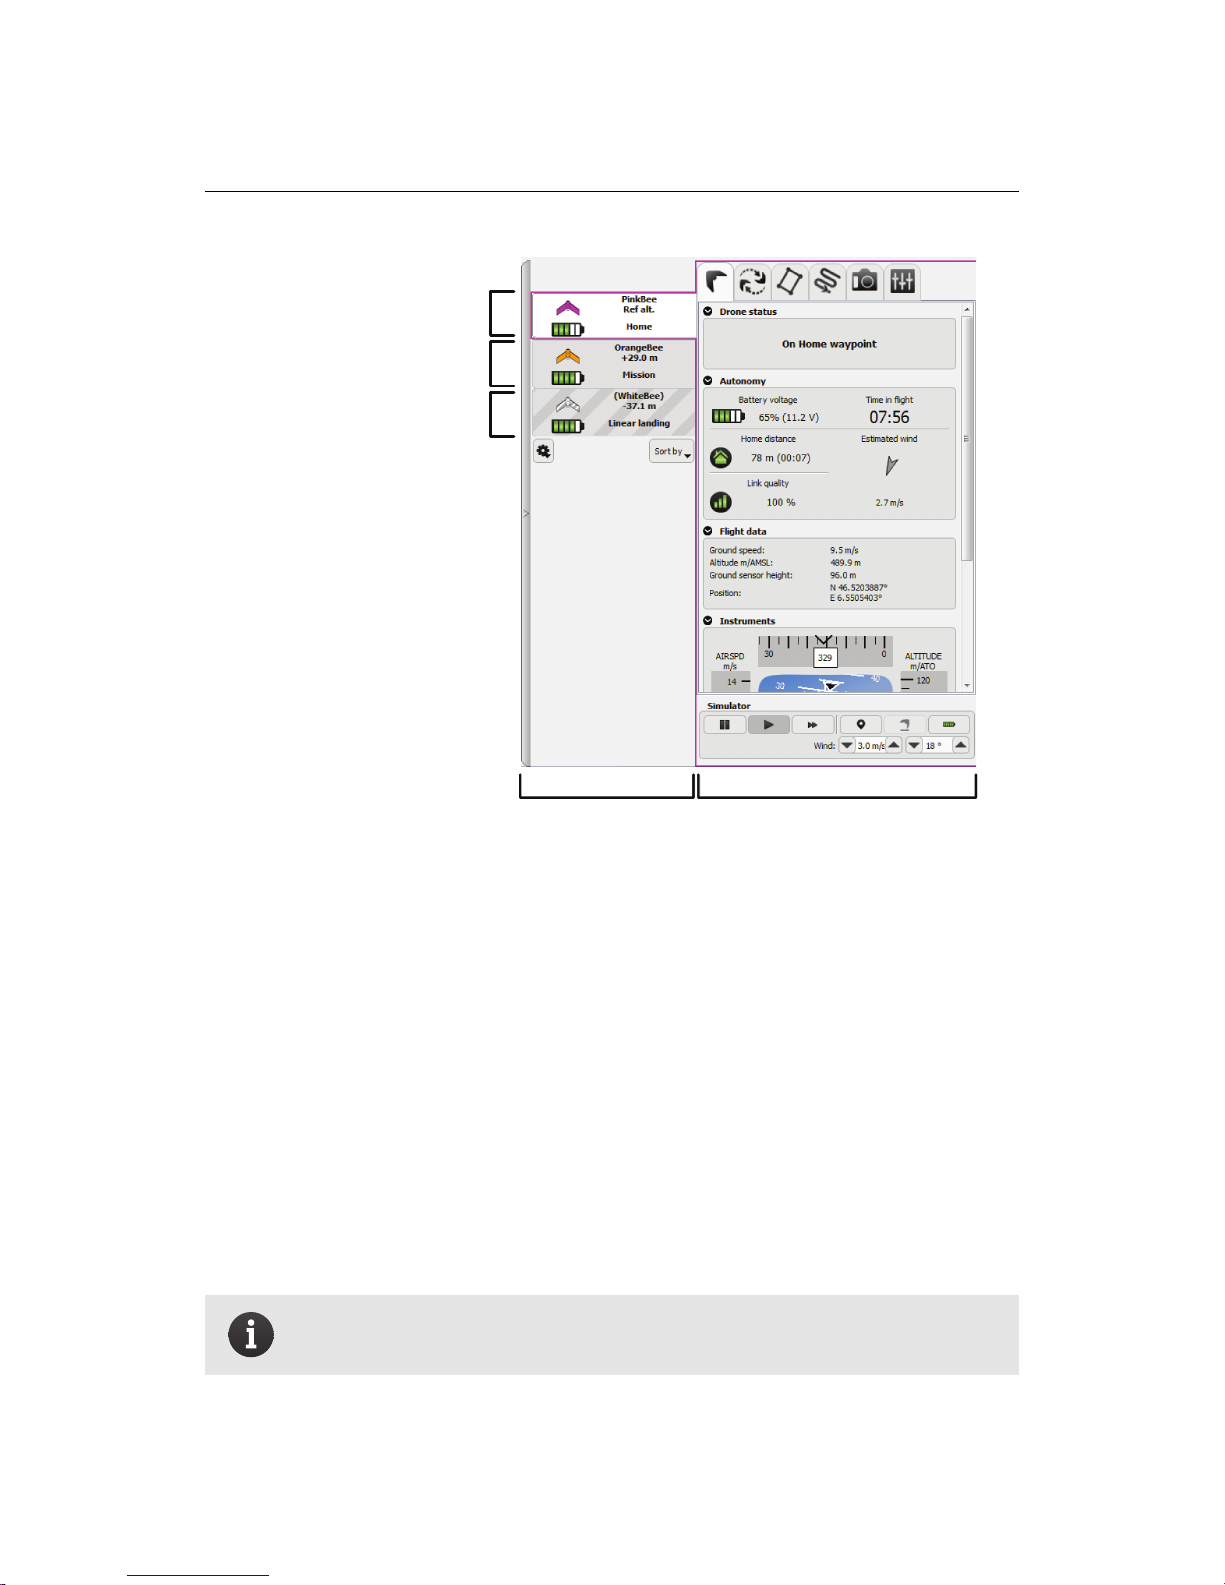
Advanced functionalities
selected drone
SidebarMulti-drone panel
second drone connected
to this computer
drone shared through
network
One advantage of flying multiple drone dronesatonceistocovermore area in less
time. eMotion can automatically upload a multi-flight mission to all connected
drones in a single click. To achieve this, follow this procedure:
1. Go to the Mission Planning tab and prepare the required mission area (this
can be done with any of the connected drone selected). Make sure that
the number of flights required matches the number of connected drones.
If needed, the ‘Max flight time’ option can be lowered to force the mission
planner to split the mission in several flights (see section ‘Mission Planning
tab’ on page 86).
2. Select ‘Upload to all’ from the drop-down list of the ‘Upload button’.
Note: You can onlysplitamissionbetweendronesof the same model
and that are using the same camera.
64
Page 65
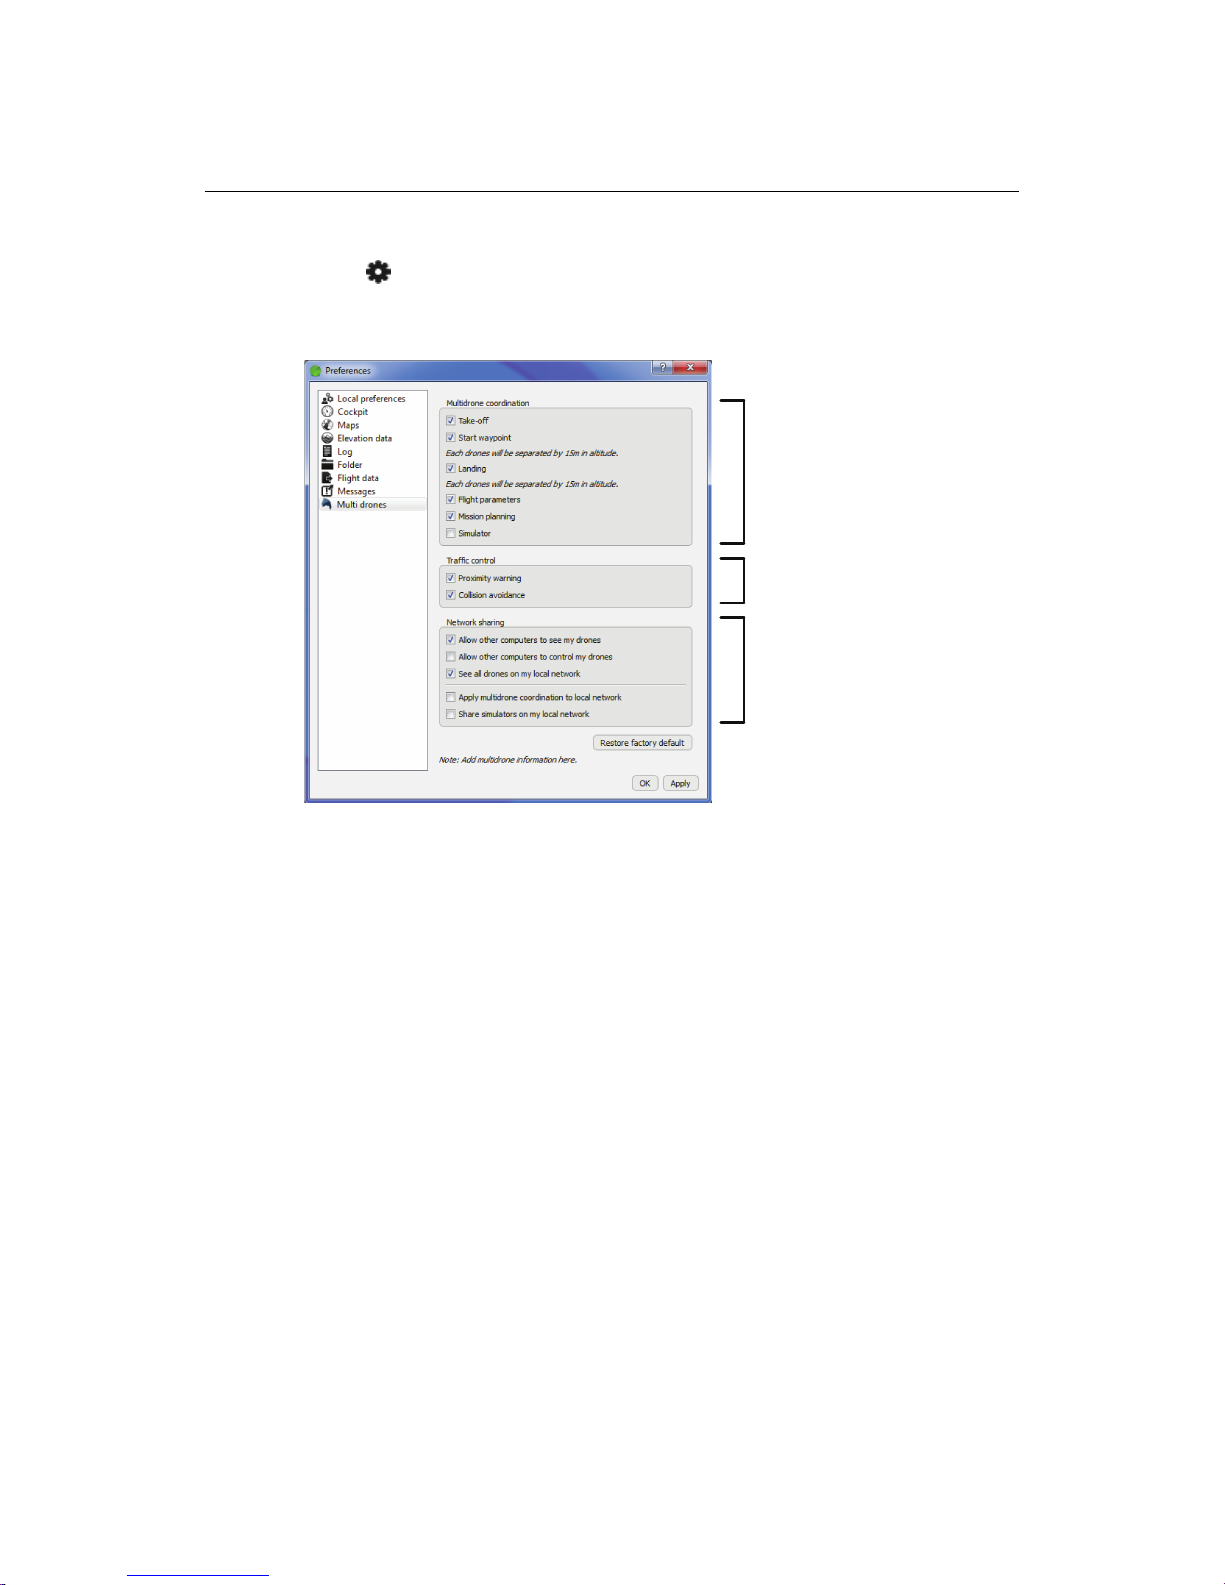
Understanding aerial mapping with the swinglet CAM
Clicking on the icon in the Multi-drone panel allows you to either connect a
new drone or to bring up the Multi-drones preferences pane.
Multi-drone
coordination
Traffic control
Network sharing
eMotion provides Multi-drone coordination options to synchronise various waypoints and parameters among connected drones:
• Take-off: Synchronisingthetake-off applies specifically toDirectionaltake-
off heading and transition altitude.
• Start waypoint: When the Start waypoint is synchronised, eMotion will
use thesamelocationand altitude for the Start waypoint of eachconnected
drone. Every modification to the Start waypoint of one drone is thus transferred to all other drones. To prevent collisions between drones, eMotion
will automatically create a stack by incrementing the altitude ofeachdrone
that is currently circling the Start waypoints to ensure a 15 m separation.
The base altitude of the Start waypoint, which is the altitude of the lowest
drone in the stack, can be set in the Multi-drone Panel.
• Home waypoint and landing: Similarly to the Start waypoint, when the
Home waypoint is synchronised eMotion will us the same Home waypoint
65
Page 66
Advanced functionalities
for all connected drones. A stack will also be created to avoid collisions
between multiple drones circling the Home waypoint.
Caution: As eMotion defines the Start and Home waypoints in ATO.
It is therefore critical for all dronesto take off from the exact same
location to achieve altitude separation and collision avoidance over
these two waypoints.
• Flight parameters: This option will synchronise all the parameters in the
‘Flight parameters’ tab across all drones. This includes the Working area
radius and ceiling, take-off transition altitude, Security action parameters,
etc.
• Mission planning: This optionwill share the sameMission Area among all
connected drones.
• Simulator: When checked, repositioning a simulated drone on the map
will reposition all simulated drones at the same time.
In addition tothe altitude separation onthe Start and Home waypoints described
above, eMotion provides two traffic control mechanisms to help avoid collision
between drones in flight:
• Proximity warning: When enabled, a visual and audible warning will be
emitted if two drones are on a trajectory potentially leading to a collision
in less than 7 seconds.
• Collision avoidance: When enabled, eMotion will constantly monitor the
trajectory of the connected drones and automatically put one drone in a
temporary hold pattern (similar to the HOLD POSITION function, see section ‘Control Bar’ on page 76) until it is safe to resume the flight. Priority is
given to drones with the lowest battery level, engaged in a landing procedure or with an active error or warning.
66
Page 67
Understanding aerial mapping with the swinglet CAM
Caution: All collision avoidance mechanisms are implemented by
eMotion on the ground computer. The drones’ autopilot do not communicate between themselves and do not have knowledge of each
other’spositions. It is therefore critical to keep alldrones connected
to eMotion at all times and remain well inside communication
range.
Note: While eMotion strives to avoid all collisions, the operator is ul-
timately responsible to ensure flight safety. In particular, situations
involving more that two drones in converging trajectories may not
always be handled automatically in a fully safe manner. It is recommended to use slightly different altitudesfor each dronewhen flying
more than two drones at a time to limit the risk of collision.
In more advanced scenarios you may wishtoshare the position and eventhe control of a drone across a local area network. eMotion provides the following Network sharing options:
• Allow other computers to see my drones: All computers that are run-
ning eMotion and are connected to the same network will be able to display the position, status and other parameters of the drones connected to
your computer.
• Allow other computers to control my drones: All drones currently con-
nected to your computerare not only displayed, but can be fully controlled
by other computers running eMotion on the same network.
• See all drones on my local network: Check this box to display the po-
sition and other parameters of drones connect to other computers on the
same network.
• Apply multi-drone coordination to local network: Check this box to
synchronise all the selected parameters in the Multi-drone coordination
preferencesacross all drones that areconnected to the samenetwork (provided that they have checked the ‘Allow other computers to control my
drones’ option).
67
Page 68
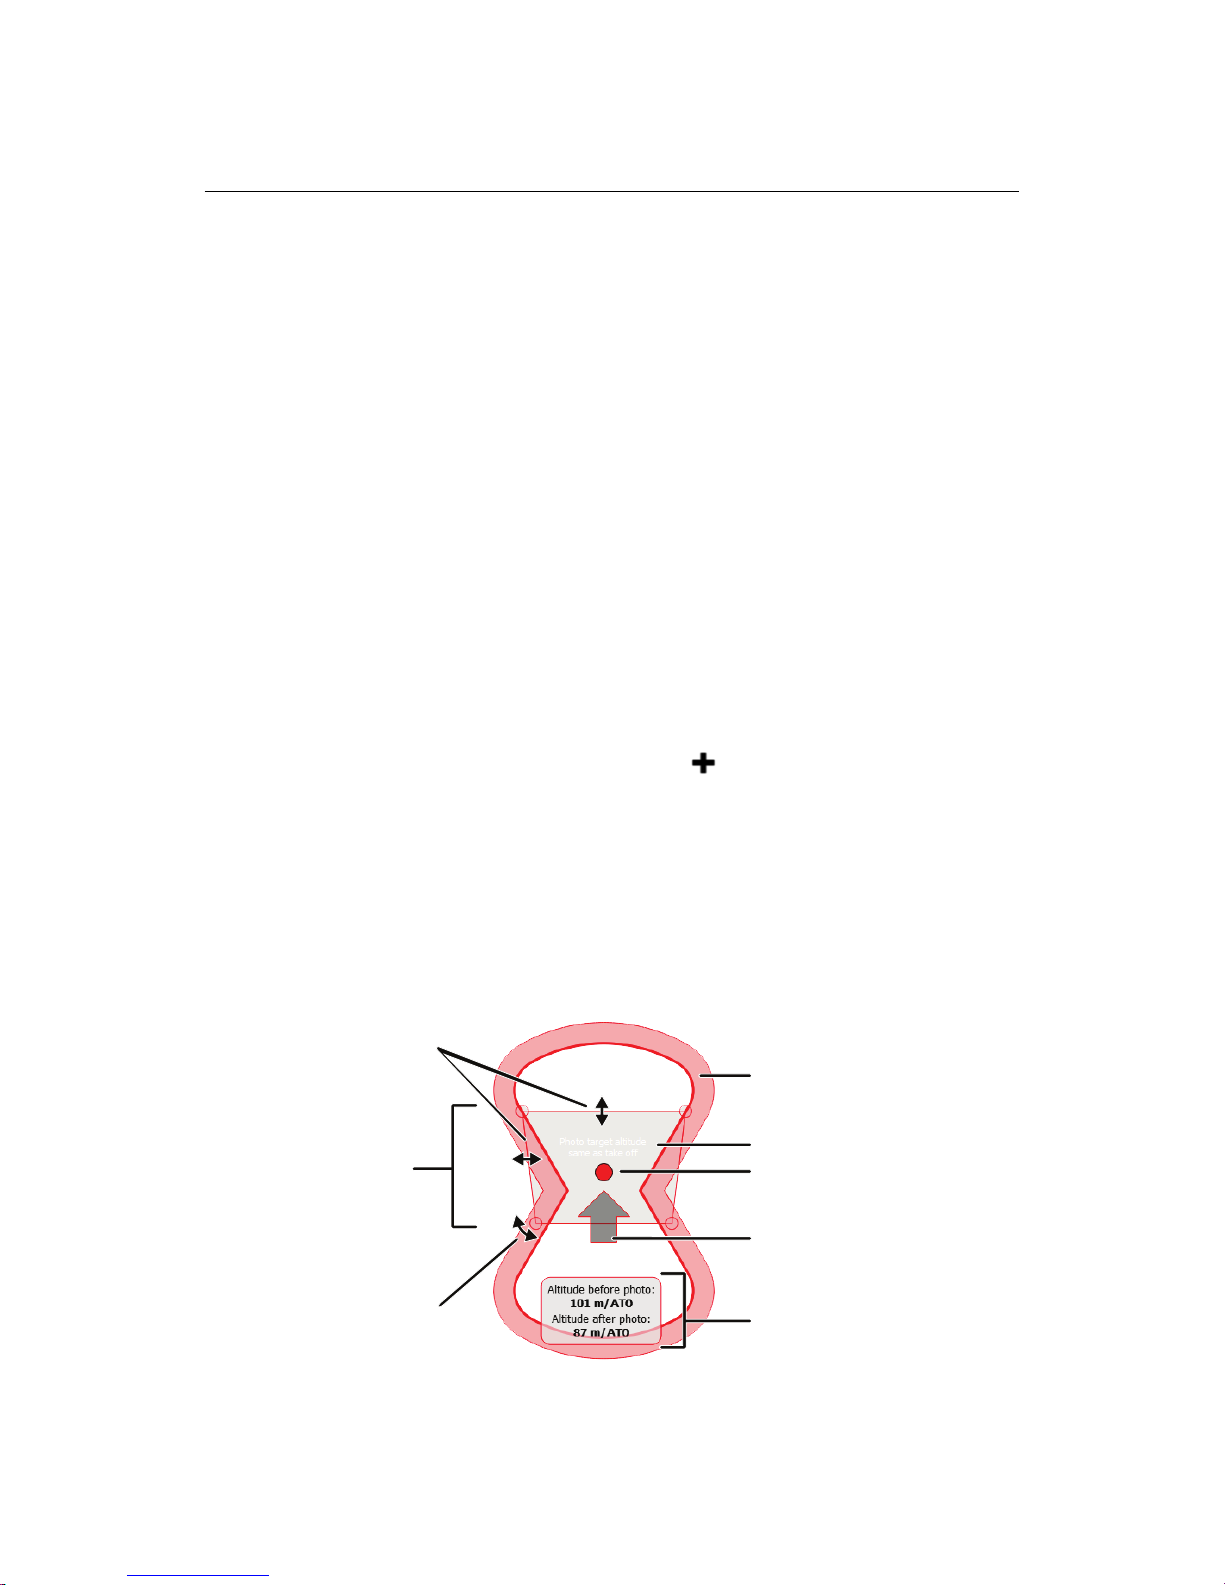
Advanced functionalities
• Share simulators on my local network: If this boxis checked,allNetwork
sharing options apply toboth real and simulated drones connectedtoyour
computer. In unchecked, they only apply to real drones.
4.7 Individual photo targets and oblique imagery
In some cases it may be interesting to take oblique photographs of objects, for
example to provide a nice image for documentation or to increase the quality
of 3D models that contain vertical facades and surfaces. eMotion includes a tool
for defining photo targets with a specific distance, heading and pitch angle. The
drone can then orient itself and capture the image using a patent-pending pitchdown manoeuvre.
Capturing an oblique image can be done easily by following these steps:
1. Add a new photo target by clickingon the button in the Camera tab. Use
the cross-hairs to place the photo target on the location of interest in the
Map Area. You may also right-click anywhere in the Map Area and select
‘Add photo target here’ from the contextual menu. The photo target will
appear as a circle in the Map Area with an estimated image footprint, a
manoeuvre zone and a status panel with estimated altitudes before and
after the image is taken.
estimated
footprint
rotate to change
heading
move in the arrow direction
to change pitch/persepctive
estimated altitudes
before/after photo
manoeuvre zone
photo target
photo target altitude
resize to change
ground resolution
68
Page 69
Understanding aerial mapping with the swinglet CAM
2. Select the desired heading and pitch angles of the image by rotating the
image footprint and moving the photo target arrow, respectively. The estimated image footprint can help you choose the required angles. You can
also set the angles manually in the ‘Photo targets’ section of the Camera
tab.
3. Define the desired ground resolution at the photo target within the Camera tab. You can also adjust the ground resolution by resizing the photo
footprint in the Map Area.
Caution: Be sure to define a ground resolution that is high enough to
allow the drone to recover from its pitch manoeuvre by paying close
attention to the ‘Minimum altitude after photo’ parameter. We recommend that you do not define parameters that result in an ‘Minimum altitude after photo’ of less than 30 m, in particular when selecting a high pitch angle.
4. Define the altitude of the photo target, if it is not the same as the take-off
altitude. You mayuse elevation data to define this altitude by enabling the
‘Use elevation data to set absolute photo target altitudes’ checkbox.
Repeat the above steps to define multiple photo targets. After launching your
drone, click on the ‘Begin sequence’buttonin the Camera tab at any timeto begin
taking the images. The swinglet CAM will fly to the location of the first photo location, measure the wind above the location, and perform a dive (pitching down)
manoeuvre to take the oblique photo. It will perform this for all photo targets
until it has completed the entire sequence.
Taking aseries of oblique images of the same photo target atregular headingand
pitch intervals allows you to create a higher quality 3D model of a photo target.
You can use the ‘New photo target increment’ to define a desired increment angle.
Clicking on the button will then add a new photo target at the same location
as the previous target but with an incremented pitch and heading value.
A more detailed description of all the available options for taking images of individual photo targets can be found in section ‘Camera tab’ on page 97.
69
Page 70
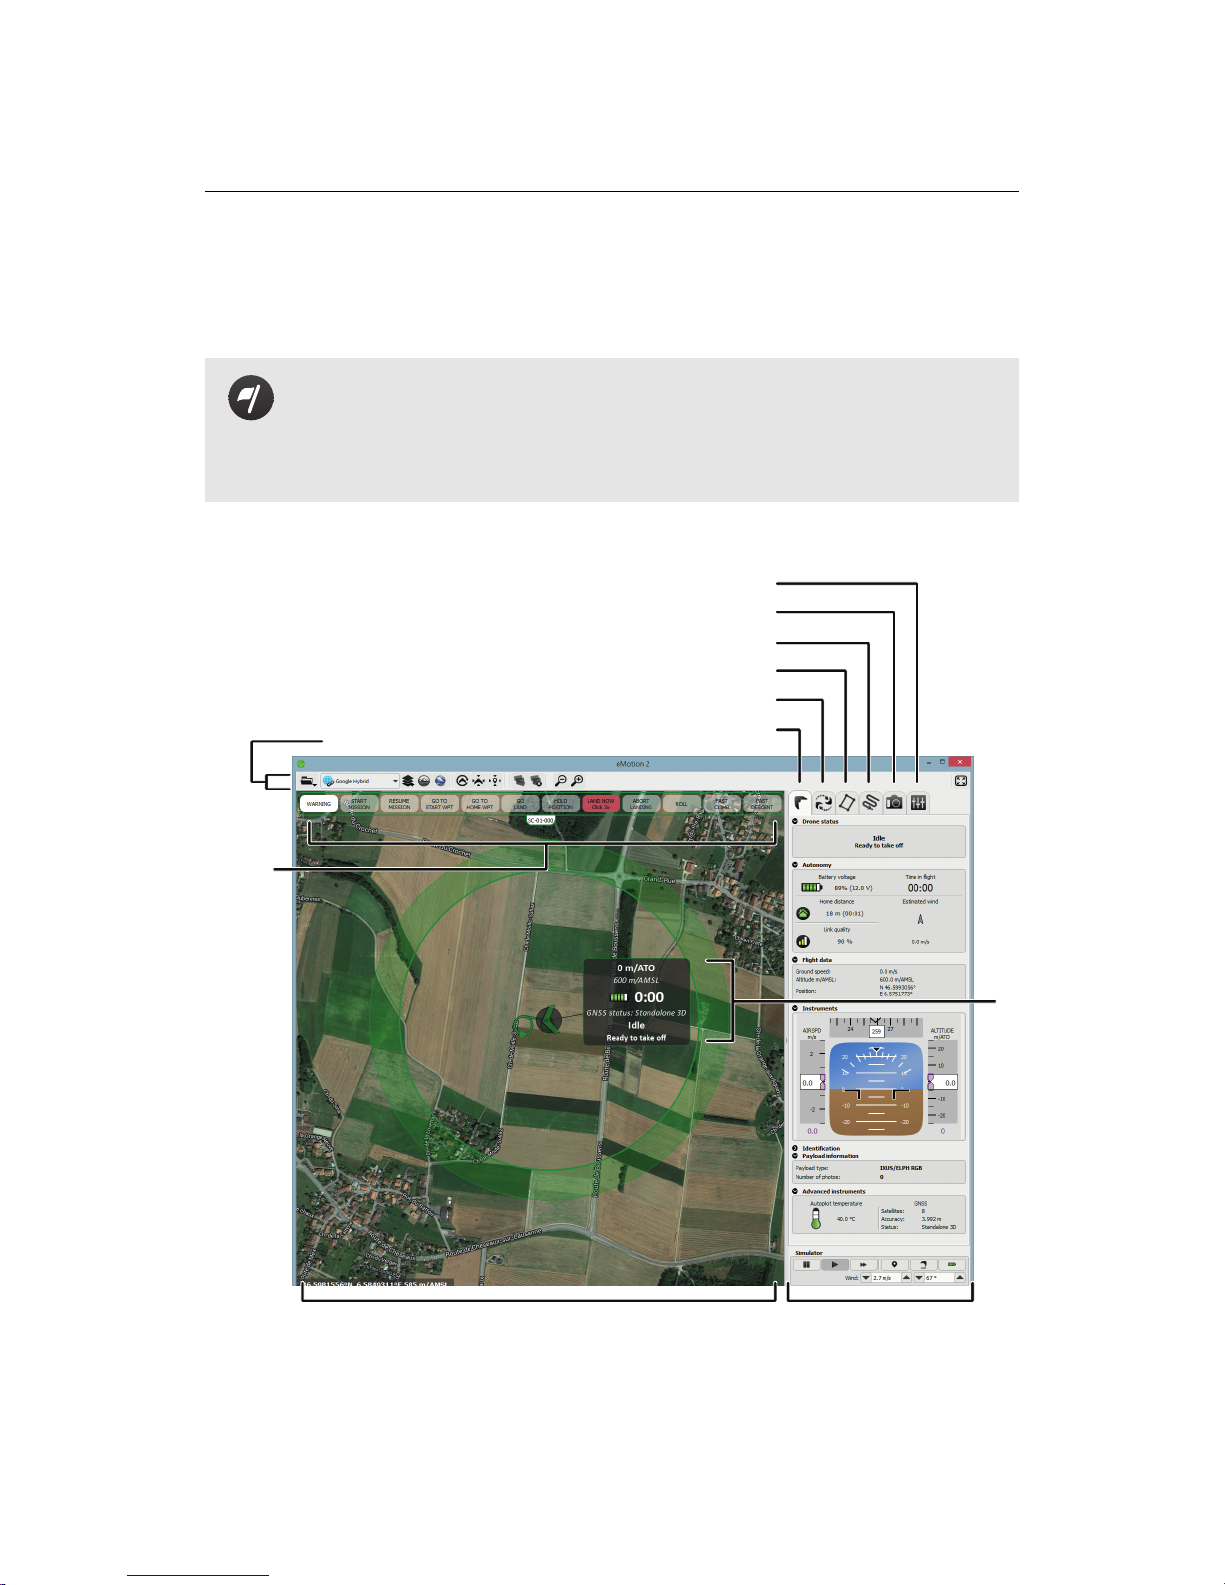
Advanced functionalities
5 eMotion in-depth guide
Goal of this section: eMotion isapowerful tool designed specifically
to work with your senseFly Ltd mini-drones. This section includes a
comprehensive guide to all the functionalities in eMotion to help you
plan, simulate and monitor your next mapping flight.
SidebarMap Area
Control
Bar
Toolbar
Status
Panel
Flight Parameters tab
Camera tab
Mission Waypoints tab
Mission Planning tab
Setup Phase tab
Flight Monitoring tab
70
Page 71
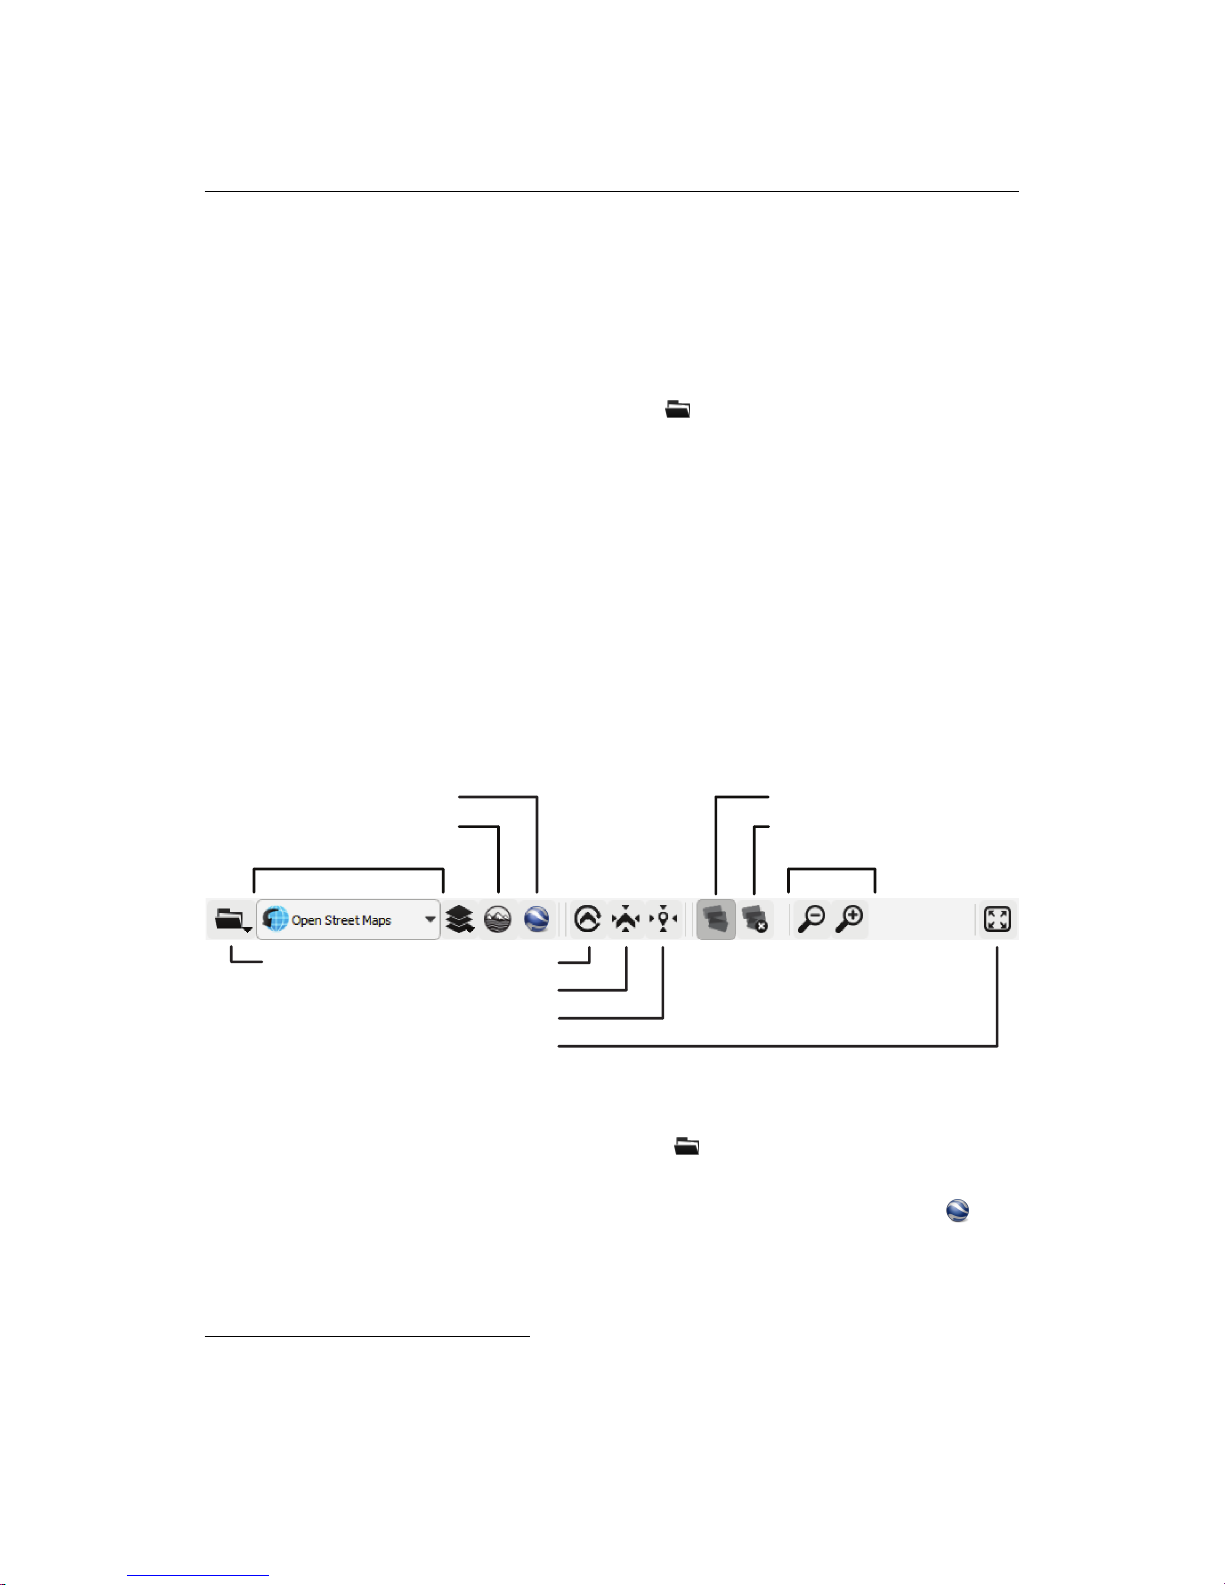
eMotion in-depth guide
The main eMotion interface is composed of a Map Area, a Toolbar and a Sidebar²⁵.
The Map Area displays the current location of the swinglet CAM, a Status Panel
with important information on the drone’s current status, and a Control Bar used
to send commands to the drone (section ‘Control Bar’ on page 76).
The Toolbarabove the Map Area includes the File menu, controls for selecting
the sourceofmap data, the display of picture footprints and various other controls
(section ‘Toolbar’ ).
The Sidebar is separated into six individual tabs that are used during different
phases of planning and monitoring a flight. The Sidebar tabs can be hidden at
any time by clicking on the left-hand edge of the Sidebar. Each tab is described
in detail in the following chapter. The Sidebar also contains controls for the Simulator (section ‘Simulator’ on page 74)
5.1 Toolbar
Map source Zoom
Google Earth display
Custom map source
Follow drone position
Center on drone
Center on coordinate
Fullscreen
File
Show/hide footprints
Clear all footprints
You can access the Filemenu by clicking on the button in the Toolbar. Fromthis
menu you can connect to or disconnect from a drone, accessthe Flight Data Manager, change eMotion preferences or import custom maps. Clicking the icon
will launchGoogleEarthTMand displaythecurrentflight trajectories of drones connected toeMotion,asdescribedindetail in section ‘Flight visualization in GoogleEarthTM’
on page 58.
²⁵ for an overview of the eMotion interface see section ‘The eMotion interface’ on page 17
71
Page 72
Advanced functionalities
You can select the background map source from the drop-down listin theToolbar,
and adjust its zoom level using the and buttons. eMotion can use many
sources of commercially available and custom mapping information. Tiles from
map sources with the icon are downloaded by eMotion from the Internet as
required and locally cached on the harddrive. Due to regulatory restrictions,map
sources with the icon cannot be saved locally and are not recommended for
use in the field.
If you anticipate the use of eMotion in conditions where connecting to Internet is
impossible, you can preload the map data by selecting ‘Download maps...’ from
the File menu. Follow the instructions in the dialog box to select the zone of
interest, map tile source and start downloading.
eMotion can also import and display custom layers which may include KML files,
custom map tiles and elevation data. To import a KML file, select ‘Import KML...’
from the File menu and select your KML file. The resulting layer will now be
available in the Toolbar by clicking on the icon, and can be clicked to display or
hide it. eMotion can display lines, polygons, paths and points saved in KML format.
Note: KML files, including associatediconsorimagesincluded within
them, are not copied to the eMotion directory and will no longer appear in eMotion if the original KML files are deleted.
Custom map tiles can also be added as a layer in eMotion. Select ‘Import custom
map...’ from the File menu and select the folder that contains the tile set. The
tile set will then appear in the list of layers in the Toolbar, accessible by clicking
the button.
Note: If you use Postflight Terra LT (see section ‘Processing image
data’ on page 43), a tile set can be generated for each project that
is directly compatible with eMotion. You can therefore create your
own map background using the swinglet CAM. You can generate the
tile set by selecting ‘Generate Google Maps tiles and KML’ from the
‘Process’ menu within Postflight Terra LT.
Whenever the swinglet CAM takes a picture, eMotion records the location and orientation of the drone and computes the approximate span of the photo on the
72
Page 73
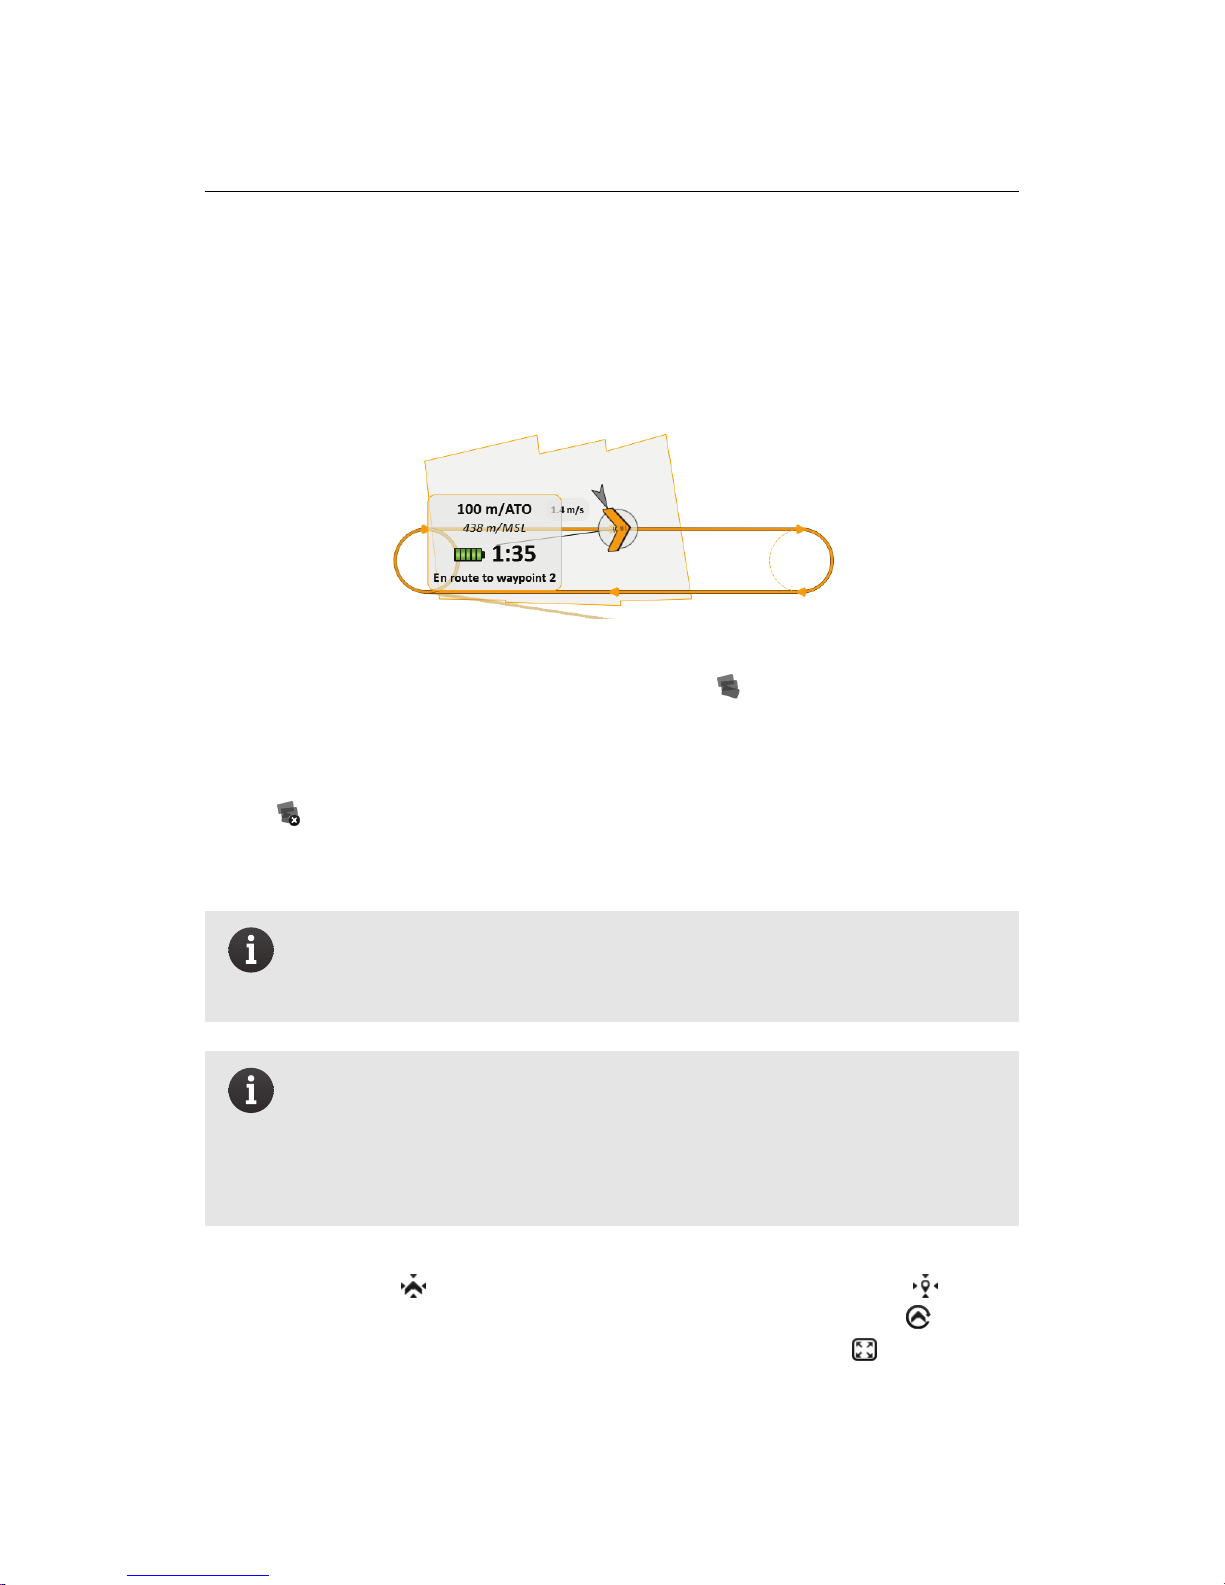
eMotion in-depth guide
ground (or ‘footprint’). All the footprints taken by a drone are added to a shaded
polygon outlined with the drone’s colour and displayed in the Map Area. This
polygon represents an estimate of the area that has been photographed by the
drone.
The footprints can be shown or hidden using the button. When hidden, the
footprints are kept in memory andnew photoscontinue to berecorded, but nothing is displayed in the Map Area. Footprints for all drones remain in the memory
of eMotion, even when a drone is disconnected or eMotion is shut down. Clicking
on the button removes all footprint polygons from the Map Area the memory
of eMotion. New picture footprints will be created for subsequent pictures that
are taken.
Note: Clearing or hiding the footprints has no influence on what is
logged by eMotion and on-board the drone during the flight, such as
the information required to geotag the images after the flight.
Note: The footprints displayed on the map are only an approximate
estimation of the actual ground coverage of the corresponding image. Cross-wind may introduce errors in the orientation of the displayed footprint compared to the actual coverage, whereas inaccurate elevation data may result inaccurate footprint size.
The Toolbar also contains buttons for centering the Map Area on the current position of the drone ( button), on a searchable location or coordinate( button)
or to continually follow the position of the drone while it is in flight ( button).
Finally you can view eMotion in full-screen mode by clicking the button.
73
Page 74
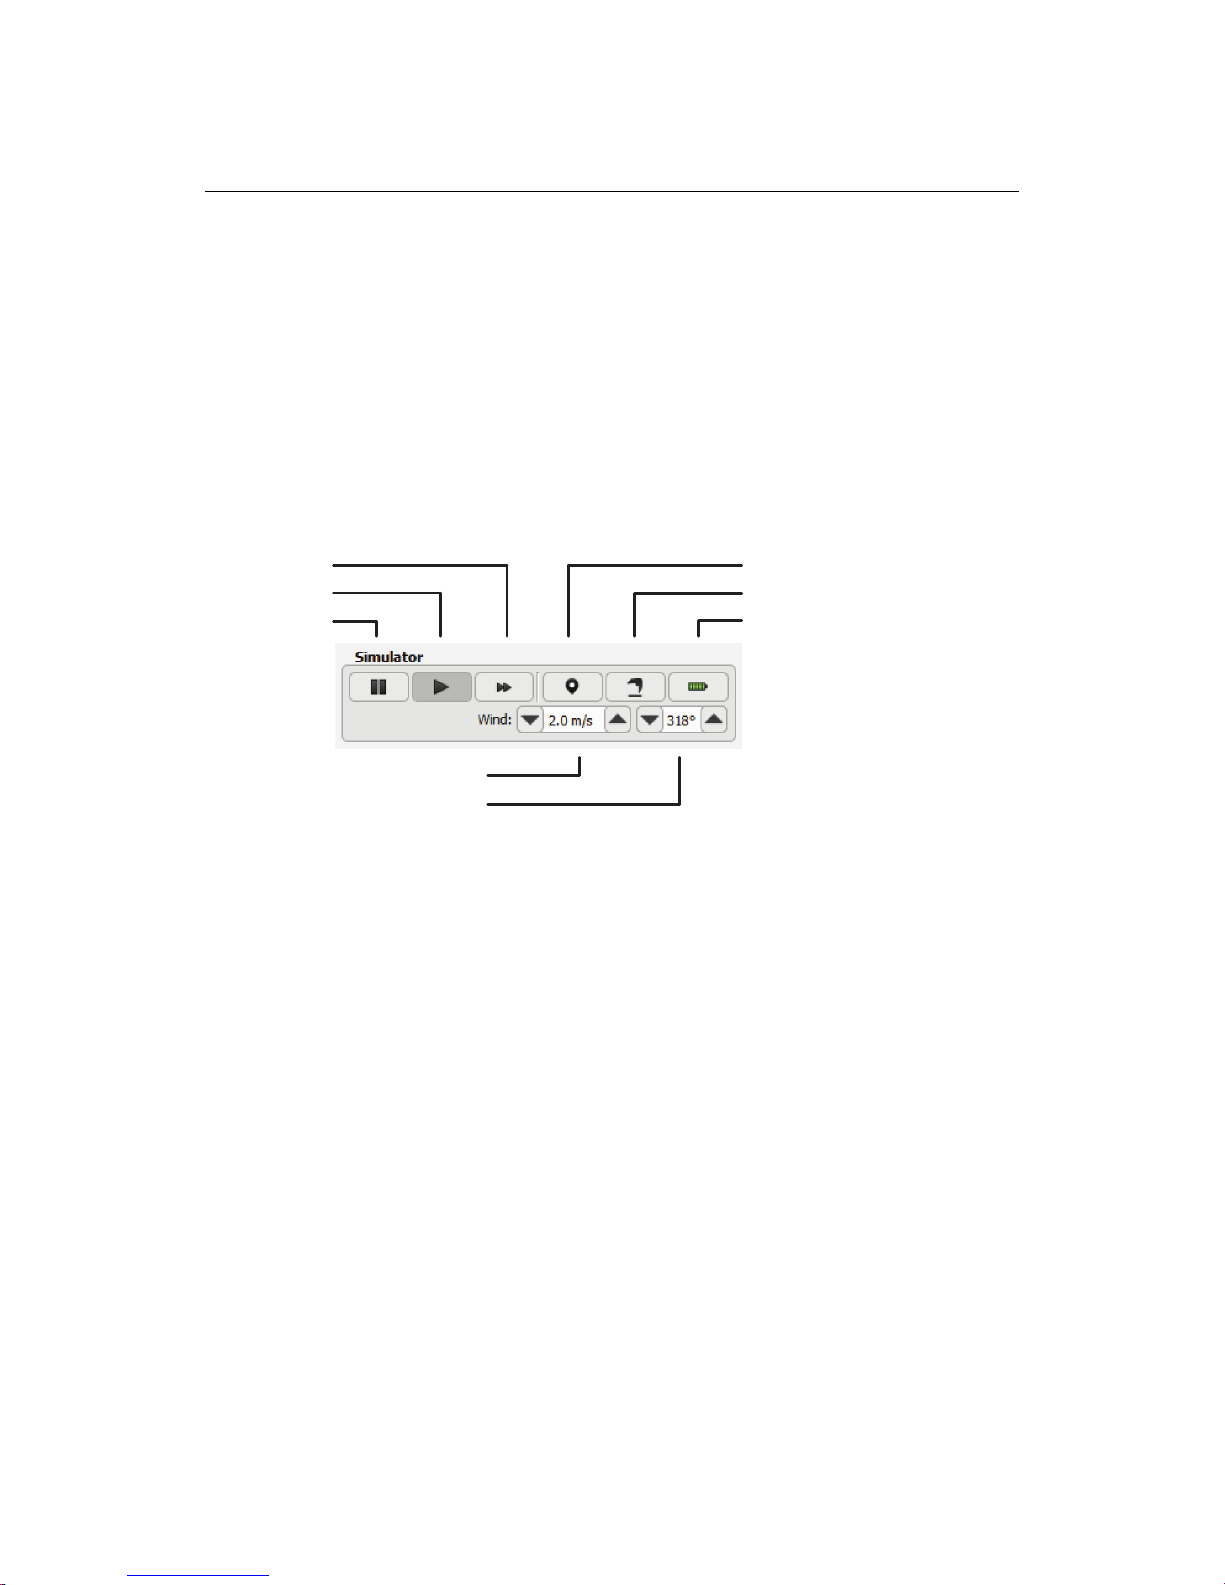
Advanced functionalities
5.2 Simulator
Familiarising yourself with your swinglet CAM and its features will allow you to
more efficiently plan and execute mapping flights, saving you time and improve
your imaging results. The Simulator in eMotion is designed to help you test the
various features of the drone and to better prepare a mapping mission before
performing it in the field. Several simulateddrones can be connected atthe same
time, allowing you to test multi-drone functionalities.
re-position take-off location
initiate take-off
instant recharge of battery
wind speed
wind direction
fast-forward
play
pause
The Simulator bar appears atthe bottom of the Sidebarof eMotion when you connect to a simulated drone. The simulated drone will go through the same preflight checks as a real swinglet CAM, after which it will update the Home to its
current position (typically the last position that was used within the simulator)
and the Start waypoint to 80 m West of the Home waypoint. The various buttons
available in the Simulator bar are described in table 1 on the following page.
Feel free to modify the wind speed, waypoint positions and other parameters in
the Toolbar and the various tabs of the Sidebar in eMotion to see their effect on
the swinglet CAM while it is in flight. Also be sure to explore the effects of the
various buttons inthe Control Bar onthe behaviour of your drone. Don’tbe afraid
to push theboundaries! Aborting a flight or causingan emergency landing in the
simulator will better prepare you for unexpected circumstances while in the field.
74
Page 75
eMotion in-depth guide
Table 1: Simulator bar buttons
Button Description
Pause Clicking the pause button will pause the simulation
and thus stop the drone while in flight. This can
be useful when you wish to change parameters or
waypoints while the drone is already in flight. Note:
this is a simulated action that is not possiblewith
the real swinglet CAM. Instead of pausing while
in flight we recommend that you use the ‘HOLD
POSITION’ function to better simulate real flight
conditions.
Play Clicking the play button returns the simulation to ac-
tual speed from the pause orfast-forward conditions.
Fast forward Clicking this button increases the speed of the simu-
lation to 4x actual speed. This allows you to shorten
the time required to simulate a complete mission.
Re-position
take-off location
Clicking this button and then clicking on a location
in the Map Area simulates the action of connecting the battery to the drone in a new location. The
drone is returned to the ground at the new location
and runs through its pre-flight checks before entering Idle mode.
Initiate take-off Clicking this button simulates a take-off procedure,
including the motor power-up sequence and the
hand launch²⁶.
²⁶ see section ‘Take-off’ on page 35 for a description of the take-off procedure
75
Page 76
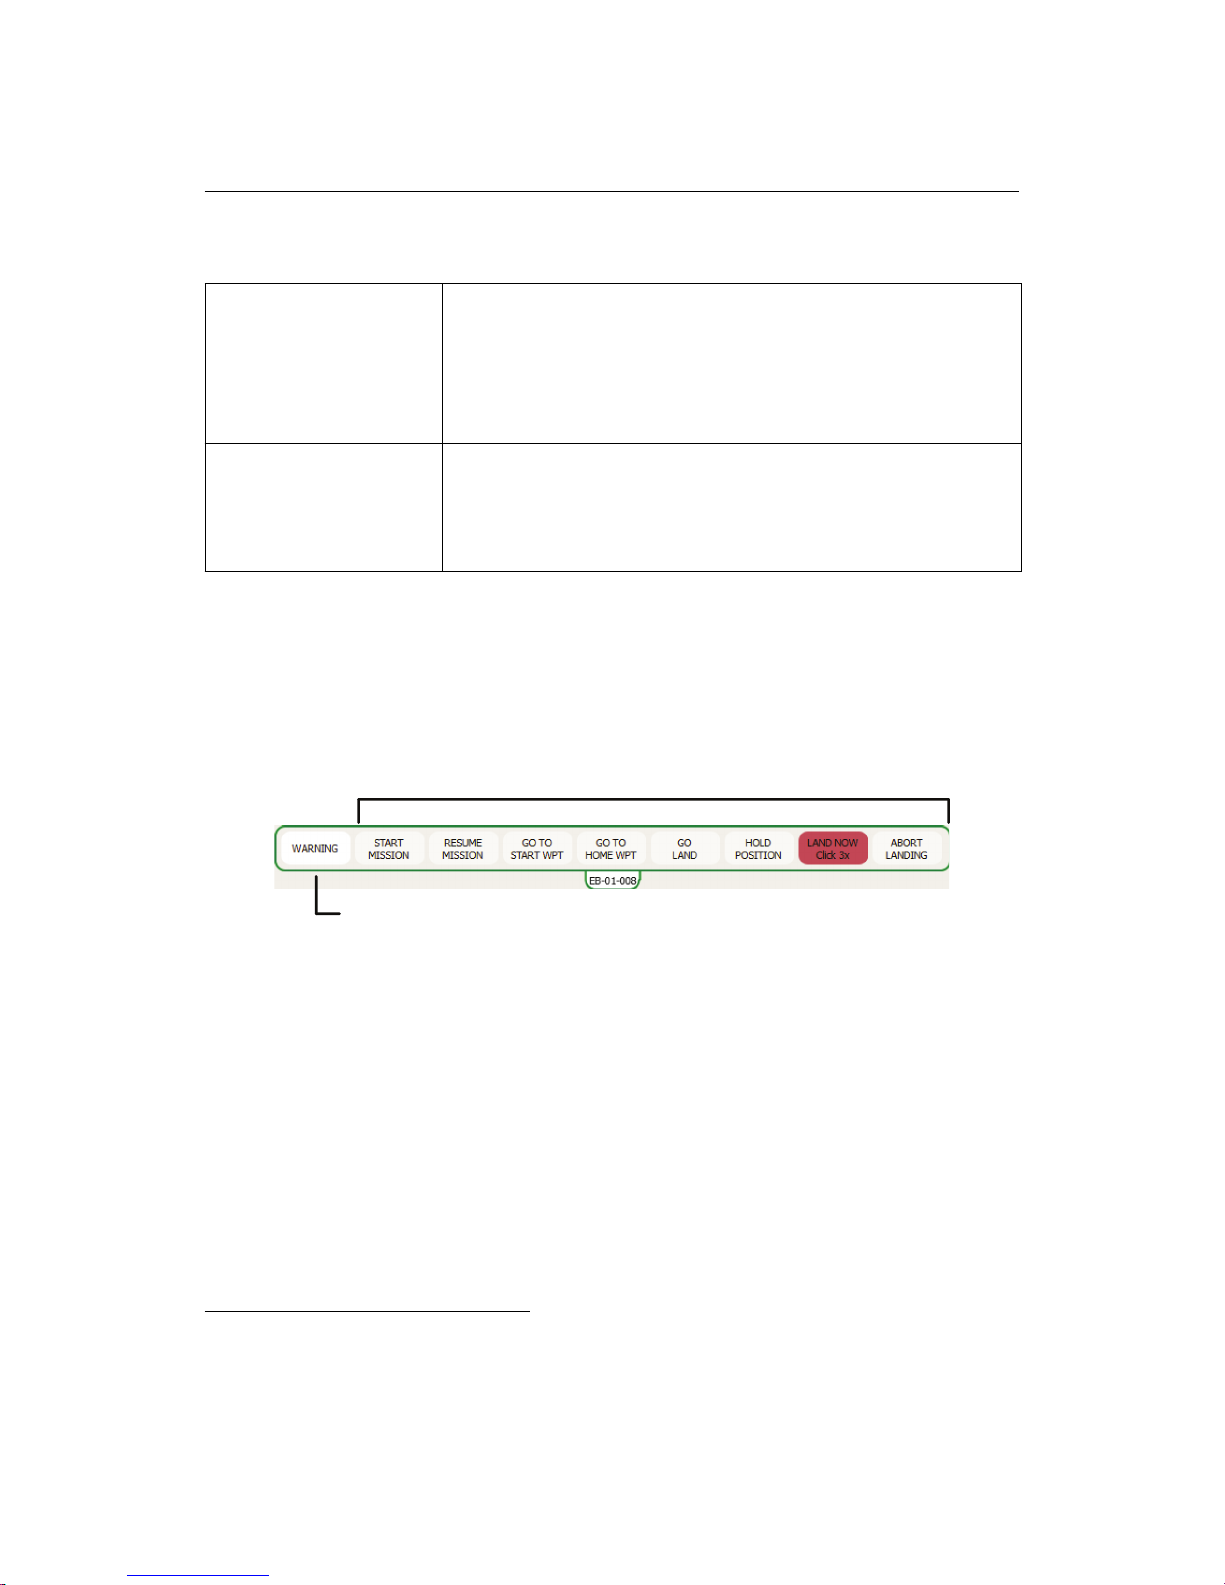
Advanced functionalities
Instant rechargeof
battery
Clicking this button will instantly recharge the battery of the drone. Note: This is a simulated action
that is not possible with the real swinglet CAM
while it is in flight.
Wind speed and
direction
These fields are used to input a simulated wind speed
and direction. A random wind speed and direction is
set when eMotion connects to a simulated drone.
5.3 Control Bar
Command buttons
Warning indicator
The Control Bar includes buttons for sending commands to the drone and for acknowledging warnings while it is in flight. Certain buttons can only be used during specific flight modes²⁷.
The Command buttons allows the operator to directly control the drone while it
is in flight. The various buttons are described in table 2 on the next page.
²⁷ see section ‘Autonomous controller and modes of flight’ on page 60 for more information on flight
modes
76
Page 77
eMotion in-depth guide
Table 2: Control Bar Buttons
Button Available Action
WARNING²⁸ Active
warning
For yellow In-flight warnings, button text
changes to ‘ACK WARNING’ and clicking will
acknowledge the current warning. For red
Critical failures, button text changes to ‘CRITICAL FAILURE’ and cannot be clicked.
START
MISSION
No active
Security action
Fly towards the first active waypoint in the
waypoint list and start the mission from the
beginning.
RESUME
MISSION
Not in Perform
Mission mode
Return to the last position reached during
the mission and continue the flight plan.
GO TO
START WPT
No active
Security action
Fly towards the Start waypoint, circle and
wait for next command.
GO TO
HOME WPT
Anytime Fly towards the Home waypoint, circle and
wait for next command.
GO LAND Anytime Fly towards the Home waypoint and initiate
landing procedure.
HOLD
POSITION
No active
Security action
Create a virtual waypoint at the current location and altitude, circle around this point and
wait for next command.
²⁸ see section ‘Troubleshooting’ on page 126 for a full description of In-flight warnings and Critical
failures that may occur
77
Page 78
Advanced functionalities
LAND NOW
Click 3x
Anytime Initiate a Circular landing around a 20 m ra-
dius waypoint at the current location. Must
be clicked 3 times in quick succession to
be engaged.
ABORT
LANDING
During Circular Landing or
Emergency
Landing mode
(if no active
Critical failure)
Circular landing: abort current landing procedure, return to the altitude of the Home
waypoint, circle the Home waypoint and
wait for next command.
Emergency landing: (only available if there
is no active Critical failure) abort current
landing procedure, return to the location
wheretheEmergency landing was triggered,
circle and wait for next command.
78
Page 79
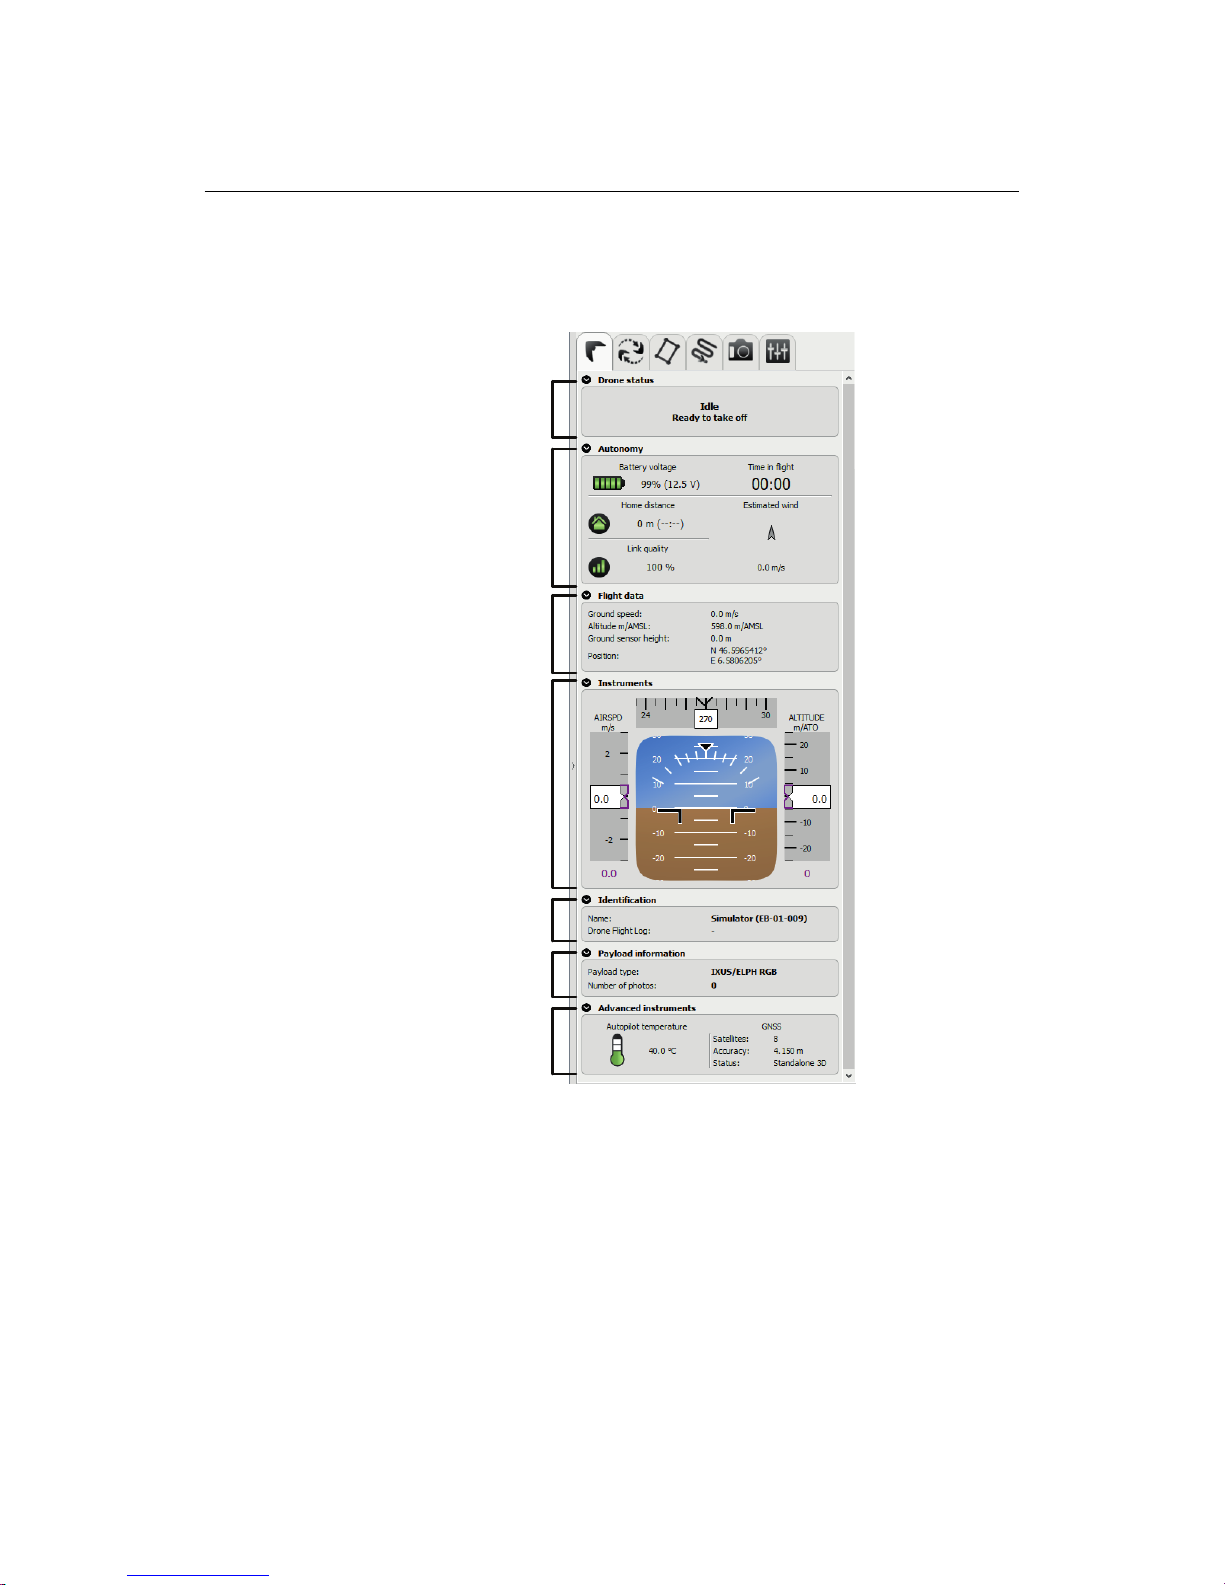
eMotion in-depth guide
5.4 Flight Monitoring tab
Drone status
Instruments
Identification
Autonomy
Flight data
Payload information
Advanced
Instruments
The Flight Monitoring tab can be used to monitorthe swinglet CAM during amapping mission and is the default tab that is displayed when you click anywhere on
the map area that does not have a symbol. The tab is split into the following sections:
• Drone Status: The status of the plane keeps you informed on what the
drone is currently doing. This can include mission actions such as ‘Taking
79
Page 80
Advanced functionalities
photo’ or ‘Going to waypoint’ as well as warning or failure messages such
as ‘Out of working area’ or ‘High wind’²⁹.
Note: The most important status and warning messages are reproduced in the Status Panel in the Map Area, and thus remain visible
even when the Sidebar is hidden.
• Autonomy: The battery level displays the current charge and voltage of
the battery. As the battery’s charge level decreases, the voltage decreases
as well. A fully charged battery has a voltage of 12.6 V and is fully discharged when it reaches about 9 V³⁰.
This section also displays the total time in flight, the straight-line distance
to the Home waypoint, the estimated time required to return to the Home
waypoint (based on estimated wind strength) and the quality of the radio
data link between the ground modem and the drone. The strength and
direction of the wind estimated by the drone is displayed with an arrow.
Caution: Lithium polymer batteries are chemicaldevices whose performance depends on a number of parameters, including temperature, lifetime, number of cycles, mechanical integrity, etc. Estimating
the remaining capacity of a battery can thus be tricky and the displayed value may occasionally be inaccurate. It is the operator’s responsibility to monitor battery voltage and flight time in addition to
the battery level to make sure that endurance is sufficient to complete the mission.
• Flight data: This section includes additional information that may be use-
ful during the flight, including ground speed, altitude Above Mean Sea
Level (AMSL) and the absolute position detected by the GPS on-board the
swinglet CAM.
²⁹ see section ‘Troubleshooting’ on page 126
³⁰ see section ‘Proper battery care’ on page 123
80
Page 81
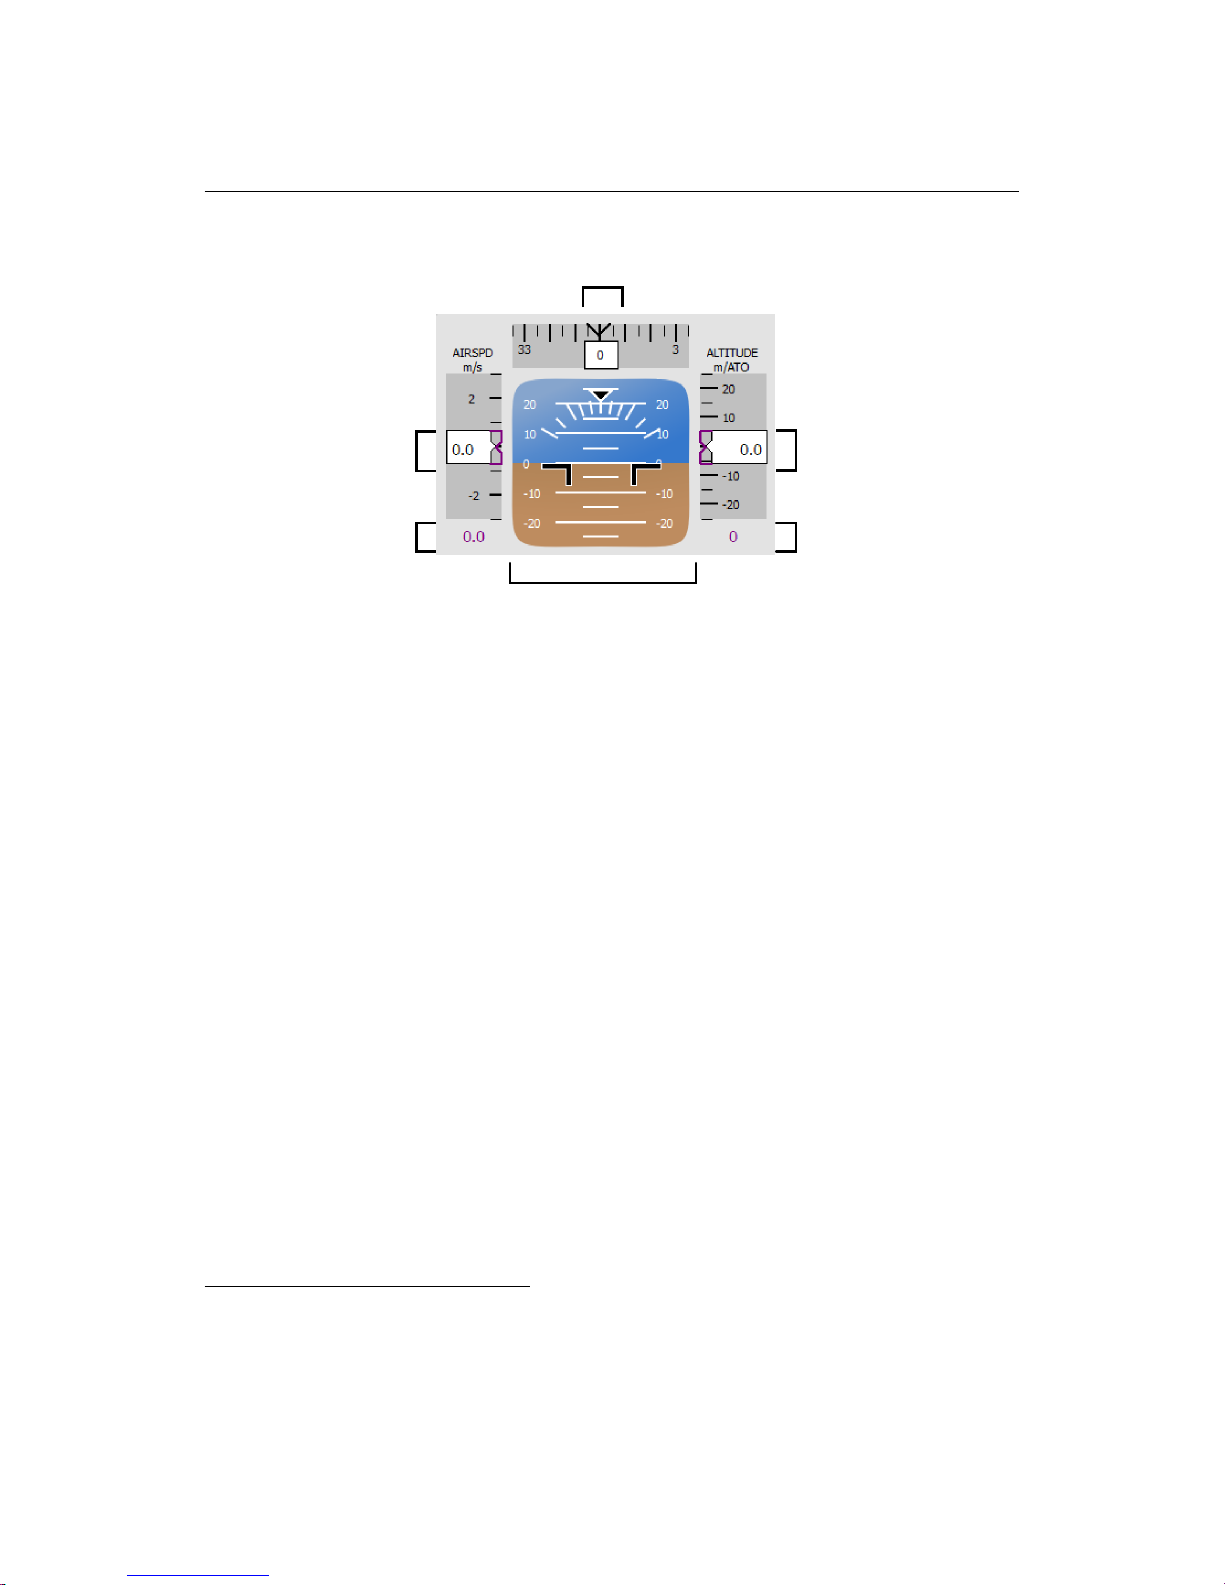
eMotion in-depth guide
current altitude over
take-off location
current heading in degrees
attitude with respect
to artificial horizon
desired altitude over
take-off location
current air speed
desired air speed
• Instruments: This display mimics the classical primary flight display used
in manned aircraft. The column on the left displays the current air speed
of the swinglet CAM as well as the desired air speed, in metres per second.
The column on the right displays the drone’s current altitude over take-off
location, as well as the desired altitude over the take-off location, in metres.
The bar at the top displays the current heading of the drone³¹. North is
indicated as 0◦, East as 90◦, South as 180◦and West as 270◦.
• Identification: This displays the serial number of your swinglet CAM and
the number of the Drone Flight log for the current flight. This number can
be used as a reference when importing flight data after a flight³².
• Payloadinformation: Thissection displays the payload currently selected
and the number of photos that has been taken since take-off³³.
• Advanced Instruments: Thissection displays the current internal temper-
ature of the drone, the number of GPS signals detected and the estimated
accuracy of the the position.
³¹ this feature is only accurate when in flight
³² see section ‘Importing images and flight data’ on page 43
³³ see section ‘Camera tab’ on page 97 for instructions on changing the payload type
81
Page 82
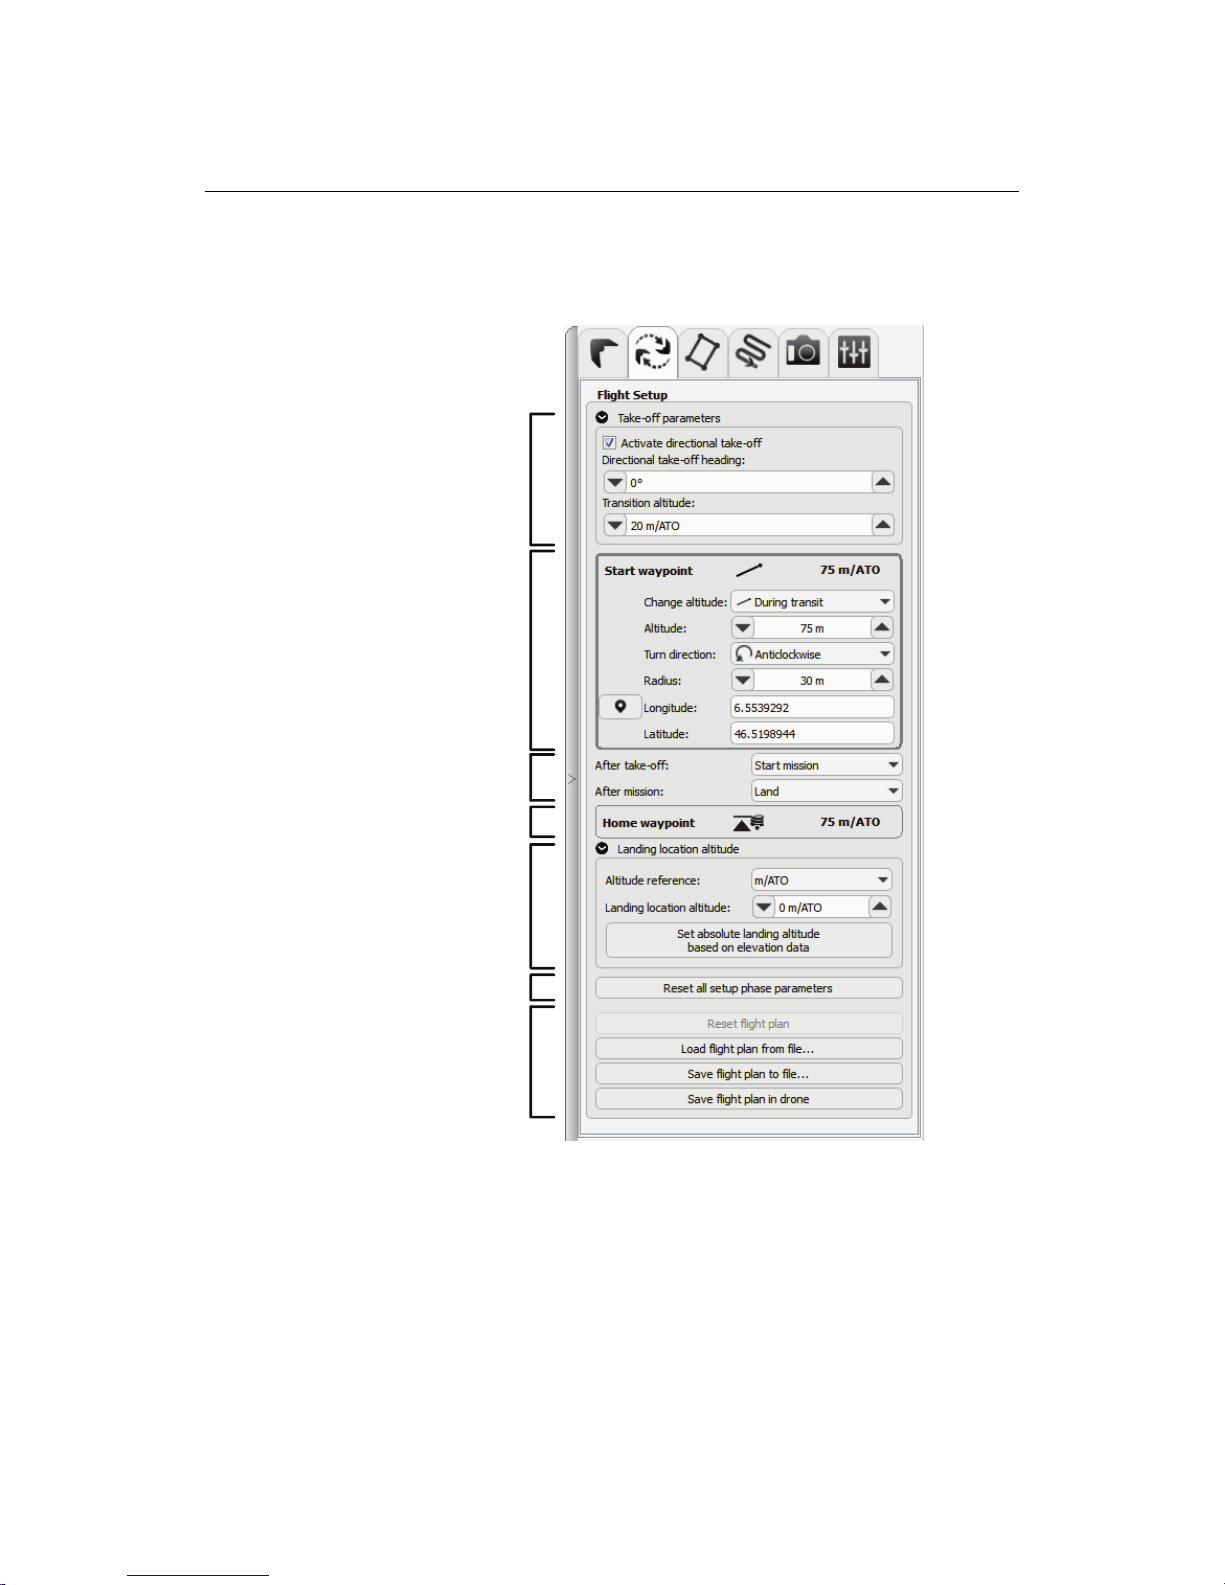
Advanced functionalities
5.5 Setup Phase tab
Start waypoint
Landing
Home waypoint
After mission and
take-off actions
Take-off parameters
Flight plan actions
Setup phase reset
The Setup Phase tab is used to define the setup phase of a flight plan. This phase
includes the definition of the Home and Start waypoints and the actions to be
taken before and after the mission phase of the flight plan.
The Setup Phase tab is divided into the following sections:
• Take-off parameters: You can predefine atake-off heading andtransition
82
Page 83
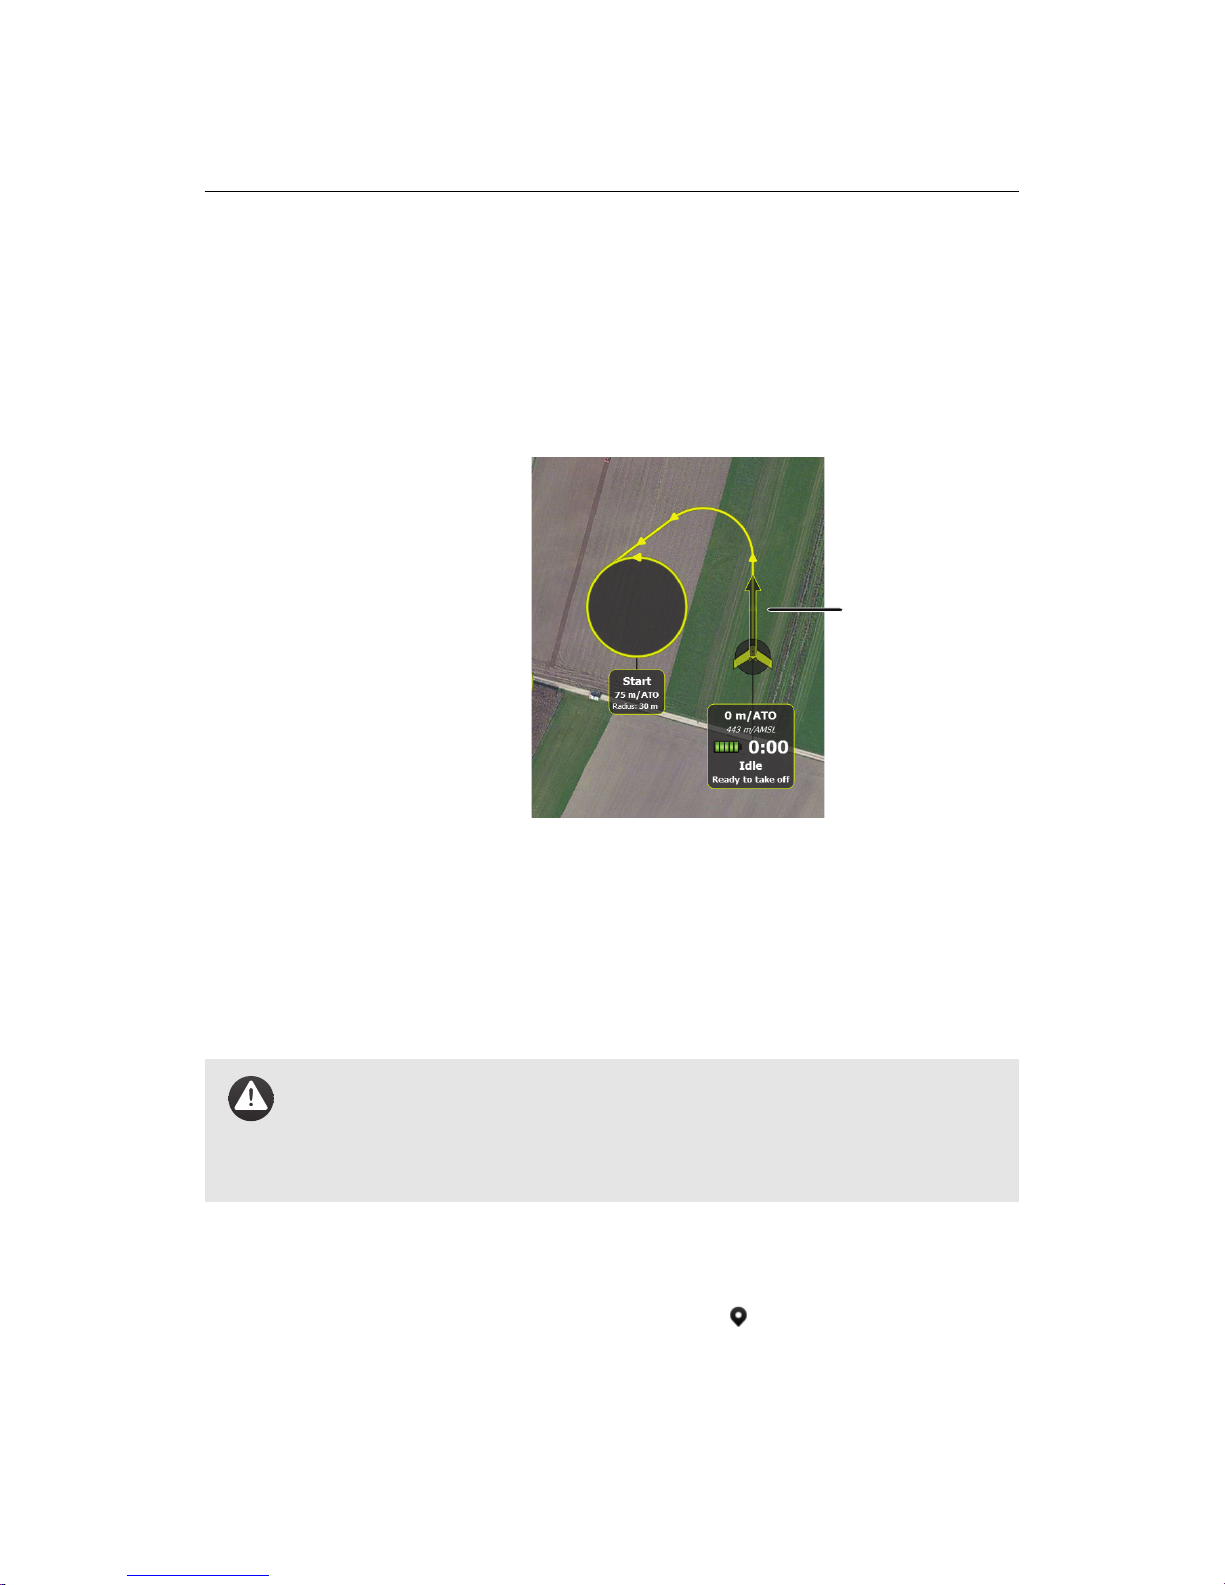
eMotion in-depth guide
altitude. To enable this feature, expand the ‘Take-off parameters’ box and
check the ‘Activate directional take-off’ checkbox. A new arrow is now displayed on the map. This arrow defines the take-off heading, the drone will
try to stay on the track defined by the arrow.
desired takeoff
direction
You can now grab the arrow on the map in order to modify the take-off
heading. Furthermore you can also pre-set the take-off direction and the
take-off transition altitude in the Setup Phase tab.
Default value: Unchecked, Heading: 0◦, Transition altitude: 20m/ATO
Caution: Setting the take-off transition altitude too low may cause
the drone to perform a change of direction too early and may result
in a crash. Setting the take-off transitionaltitude too high may cause
the drone to drift sideways after take-off if there is too much wind.
• Start waypoint: Here you set the position, change altitude parameter, al-
titude above take-off (m/ATO), turn direction and radius of the Start waypoint. You can setthe location by clicking the button and clickingon the
desired location in the Map Area.
83
Page 84
Advanced functionalities
Default values: Change altitude: During transit, Altitude: 75 m/ATO, Turn
direction: anticlockwise, Radius: 30 m, Location: 80 m West of the position
calculated from satellite signals on start-up
• After take-off: You can either command the drone to start the mission
phase immediately after reaching the Start waypoint or to wait for a command from eMotion. This second option is useful if you want to modify the
flight plan while the drone is already in flight.
Default value: Start mission
• After mission: Use this panel to select the action you wish the drone to
execute once it completes the mission phase. The swinglet CAM can either
automatically go to the Home waypoint and land, go to the Home or Start
waypoint and wait for a command or to restart the mission phase.
Default value: Land
• Home waypoint: Here you set the position, change altitude parameter,
altitude (in m/ATO or m/AMSL if ‘Land at a different altitude than take-off’
is selected), turn direction and radius of the Home waypoint. You can set
the location by clicking the button and clicking on the desired location
in the Map Area.
Default values: Change altitude: Keep highest, Altitude: 75 m/ATO, Turn
direction: anticlockwise, Radius: 20 m, Location: position calculated from
GPS signals on start-up
• Landing location altitude: You can also configurethe altitude of the land-
ing location ifit is different from the Take-off altitude. Expand the ‘Landing
location altitude’ panel and select an altitude in m/AMSL or in m/ATO. It is
also possible to predefine the landing altitude based on elevation data by
clicking on the ‘Set absolute landing altitude based on elevation data’ button. This button will pre-set the altitude each time it is clicked (i.e. if the
landing position is changed, the altitude is notautomatically pre-set based
on the Improved SRTM model, the user has to press the button each time
that the landing position is changed).
Default value: Landing location altitude: 0 m/ATO
84
Page 85
eMotion in-depth guide
• Setup phase reset: Pressing the ‘Reset all setup phase parameters’ will
reset the Home and Start waypoints to the take-off location and reset the
rest of the parameters on the tab to factory defaults. Clicking the ‘Reset
all waypoints and photo targets’ will remove all the waypoints and photo
targets in the currently loaded in the drone.
• Flight plan actions: A complete flight plan includes all the Setup phase
(Start and Home waypoints, Take-off and Landing parameters, etc.), Mission phase (waypoints), Camera (camera model, photo targets, etc.) and
Flight (working area radius and ceiling, Security actions, etc.) parameters.
The ‘Reset flightplan’resets the current flight plan to default parameters³⁴.
The ‘Load flight plan from file...’ and ‘Save flight plan to file...’ buttons
load and save the current flight plan (both setup and mission phases) to
a XML file for later reuse. You can also save the current flight plan to the
swinglet CAM’s on-board memory by clicking the ‘Save flight plan in drone’
button. Once a flight plan is saved in the drone’s memory, it will become
the default flight plan the next time the drone is started and appear in eMo-
tion uponconnection. Thedronealso keeps track of its lastwaypointduring
a flight; you can thus resumean incomplete flight after changing batteries.
Note: It is not necessary to save a flight to the autopilot in order to
fly! This is an advanced option meant toreduce the preparation time
required when the same flight is performed many times.
³⁴ this action is only available when the drone is not in flight
85
Page 86
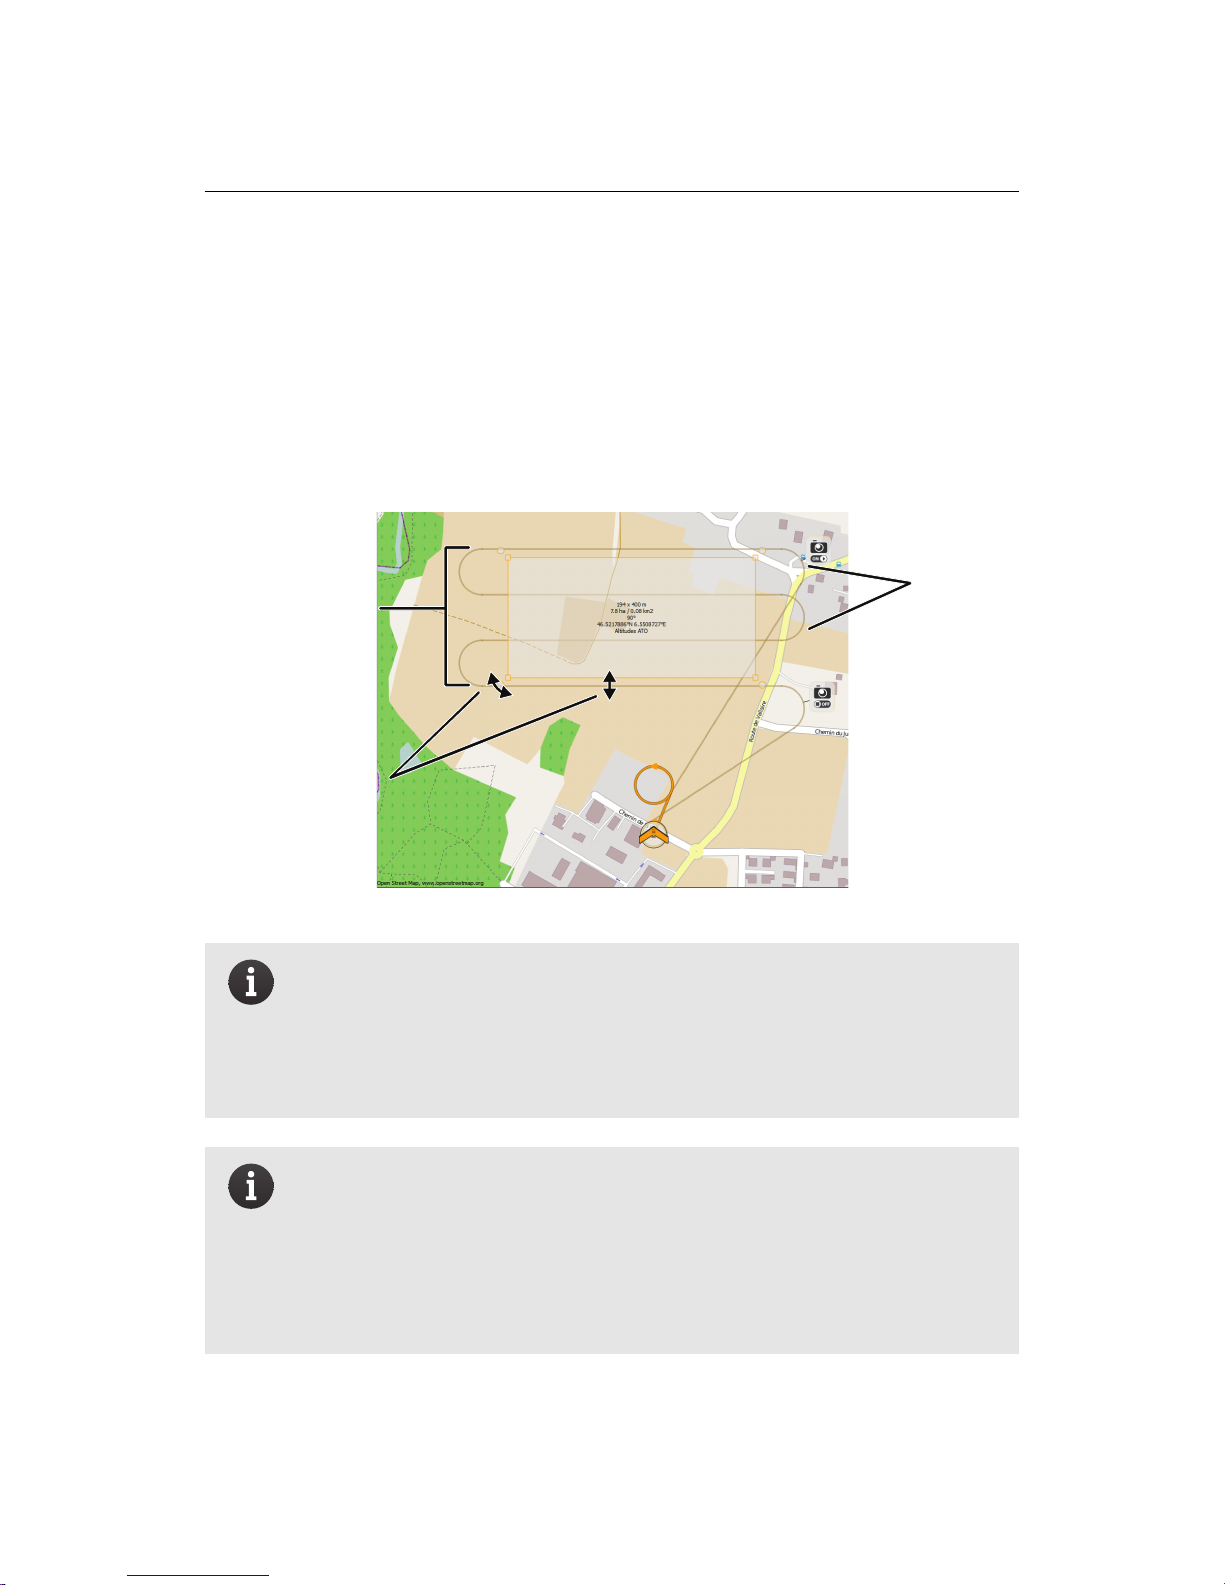
Advanced functionalities
5.6 Mission Planning tab
The Mission Planning tab is usedto automatically define a set of waypoints based
on a mission area and a set of image parameters. Clicking on this tab will make a
grey box appear in the Map Area that represents the mission area to be mapped.
You can modify this area’s location, size and rotation using the handles around it,
as explained in section ‘The mission phase of a flight’ on page 20.
mission
area
rotate,
resize,
displace
generated
flight
lines
Note: The quality of the output orthomosaic is usually lower on the
outer edges of the area that is photographed, as there is less overlap
between images. The area photographed is thus always calculated
to be bigger thanthe mission area selected soas to ensure maximum
image overlap within the mission area itself.
Note: If there is no flight plan overlaid on the mission area rectangle then the mission is too large and cannot be flown by the
swinglet CAM. This can be for two reasons: either the distance between two waypoints is too long for the drone to cover in a single
flight, or the waypoints are too far from the Take-off and landing locations.
86
Page 87
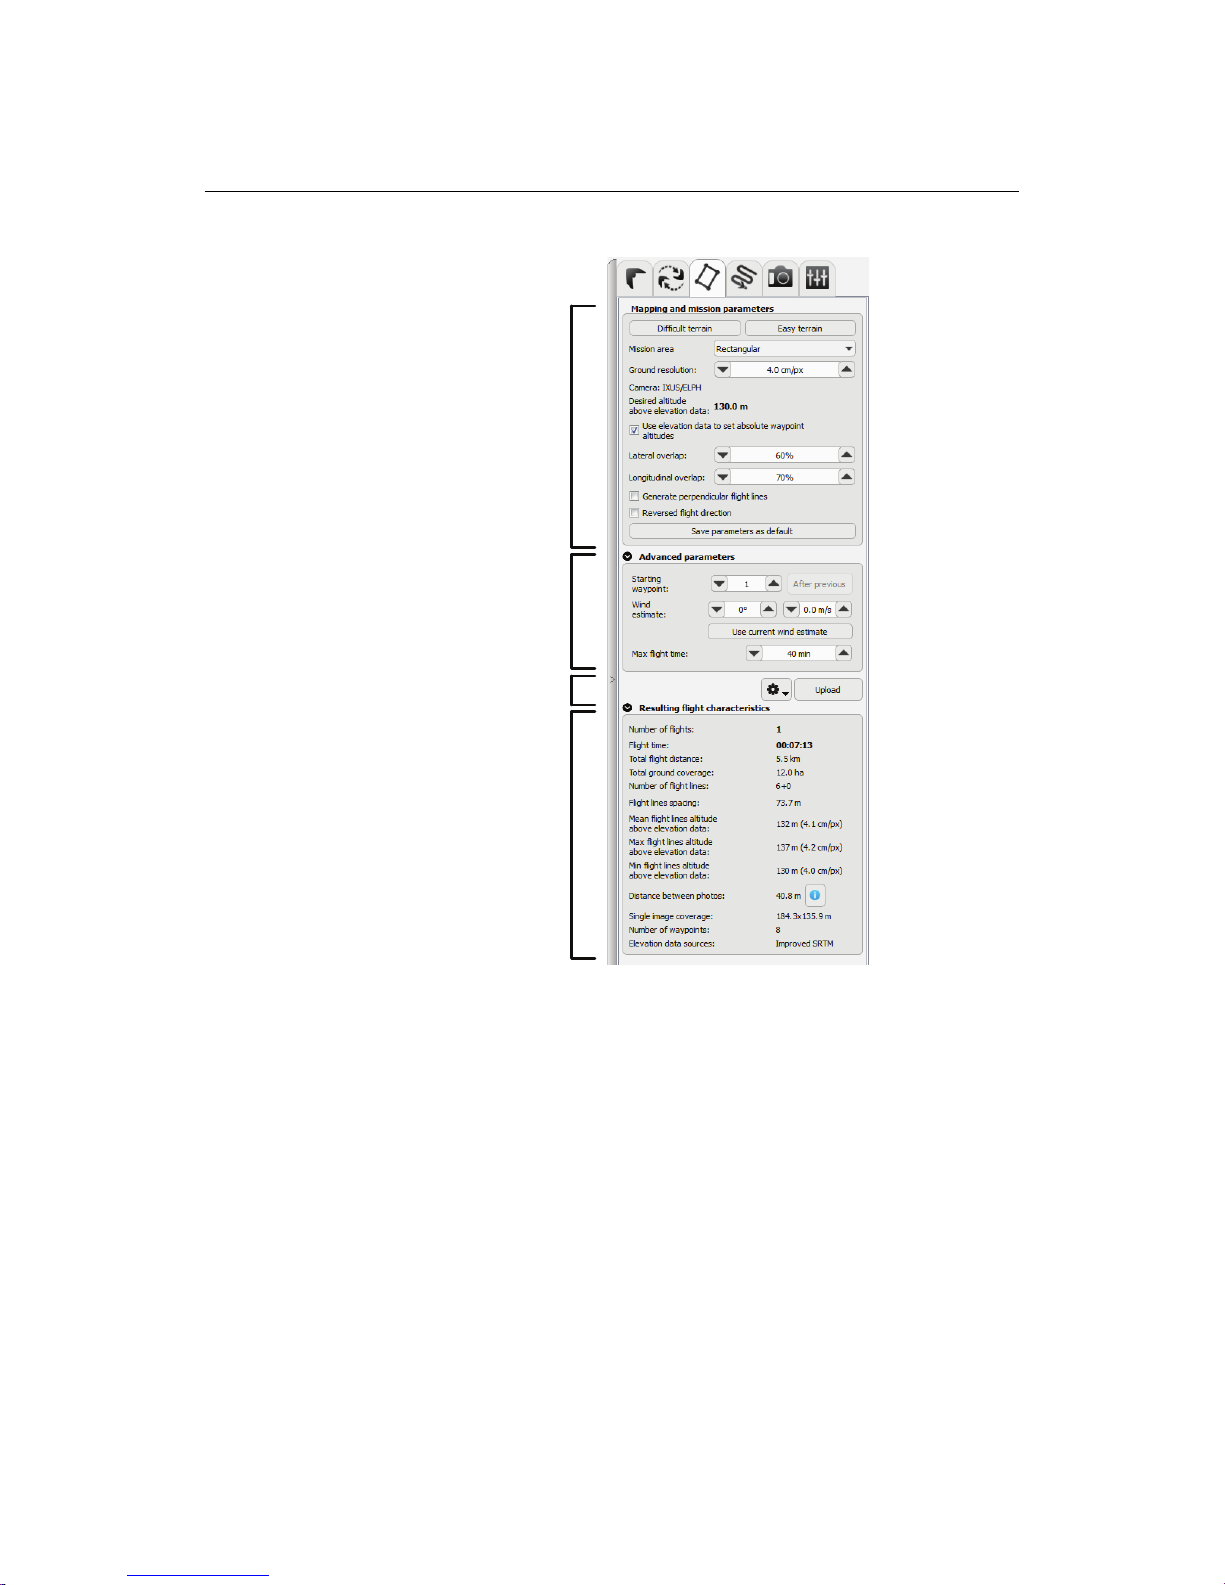
eMotion in-depth guide
Mapping and
mission parameters
Resulting flight characteristics
Mission plan actions
Advanced parameters
The Mission Planning tab is divided in several panels. The first panel, Mapping
and mission parameters, contains the parameters that define the requirements
of a particular mission:
• Difficult terrain: Clicking this button will fill in preset values to the rest
of the parameters. The Difficult terrain preset is meant for imaging terrain
with complexfeaturessuch as forests. Highimageoverlapis recommended
to increase the amount of features that can be matched between images,
though at the cost of lower image resolution (due to higher altitude).
• Easy terrain (default): Thispresetis meant for simple terrain such as quar-
ries or agricultural areas where high-resolution images can be taken with
87
Page 88
Advanced functionalities
relatively low image overlap.
Note: The preset values are recommended settings that have
demonstrated good results when images are then used in Postflight
Terra LT to create orthomosaics. Do not hesitate, however, to modify these parameters to suit the particularities of the terrain you are
mapping or the local regulations and airspace constraints.
• Mission area: You can select either a rectangular mission area for simple
terrain (as described in section ‘The mission phase ofa flight’on page 20)or
a polygonal mission area for more complex terrain (as described in section
‘Advanced polygonal mission area’ on page 55).
Default value: Rectangular
• Ground resolution: Thetarget groundresolutionto be achieved, expressed
in centimetres per pixel. This parameter is directly linked to the flight altitude: a higher resolution (few cm/px) requires a lower altitude, while a
lower resolution (many cm/px) requires a higher one.
Default value: 4.0 cm/px
• Camera: The camera payload that is currently selected³⁵. Make sure the
correct camera model is set in the flight planner to correctly calculate the
required flight line spacing and distance between photos.
• Desired altitude: The target altitude value is the desired altitude above
the ground at which the drone will take images. It is automatically calculated based on the Ground resolution and the characteristics of the onboard camera.
³⁵ see section ‘Camera tab’ on page 97 for details on changing the camera type
88
Page 89
eMotion in-depth guide
Note: swinglet CAM has a minimum distance between images that
depends on wind strengthand direction. The maximum longitudinal
overlap depends on this minimum distance as well as the calculated
altitude and the camera model. If the calculated altitude is too low
the drone may not be able to achieve the required longitudinal overlap. This will be indicated by a icon. Flying at an altitude of less
than 40 m is potentially dangerous and will be indicatedby a icon.
• Use elevation data to set absolute waypoint altitudes: Checking this
box will enable the flight planner to adjustthe absolute altitudes of all mission waypoints based on elevation data. This advanced planning mode is
described in detailin section ‘3Dmission planning using elevationdata’ on
page 56.
Default value: disabled
• Lateral overlap: Thepercentageof overlap between the ground coverage
of pictures from adjacent flight lines. For most mapping purposes, a minimum of 50% is usually required. Higher coverage values may increase the
mapping quality but will increase the flight duration.
Default value: 60 %
• Longitudinal overlap: The percentage of overlap between the ground
coverage of pictures taken consecutively in the same flight line.
Default value: 70 %
• Generate perpendicular flight lines: Checking this box creates a second
pass over the desired area perpendicular to the first pass. This option will
significantly increase the overall image overlap and therefore improve the
resulting map quality in Postflight Terra LT. It is particularly useful for diffi-
cult terrain at the cost of doubling the required flight time.
Default value: disabled
• Reverse flight direction: By default, the flight planner will design a flight
in which the drone begins a mission at the farthest waypoint and finishes
89
Page 90
Advanced functionalities
closer to the Home waypoint. Checking this box reverses the order of the
planned mission waypoints. Be cautious, however, to ensure that there is
enough reserve battery to return to the Home waypoint at the end of the
mission.
Default value: disabled
• Save parameters as default: Clicking this button willsave the current pa-
rameters of the Mission planning tab as the default ones in eMotion.
The next panel contains advanced parameters used by the flight planner:
• Starting waypoint: The waypoint ID of the first waypoint used to imple-
ment the mapping mission,as organized in the Waypoint list in theMission
Waypointstab. This option is usefulwhen includingmore than onemission
areaintoa single flight. The default value for a new mission is 1. When planning for a second area to be covered in the same flight, the ‘After previous’
button sets the starting waypoint after the waypoints used forthe previous
area.
Default value: 1
• Wind estimate: The estimated wind speed and direction. Incorrectly set-
ting the windspeed affects the estimated flight time of the swinglet CAM
and may cause it to return to Home before completing the desired flight
plan. Clicking the ‘Use current wind estimate’ button will copy the wind
speed currently estimated by the drone to the Wind estimate field.
Default value: direction: 0◦, speed: 0 m/s
• Max flight time: This parameter sets the maximum estimated flight time
for a single flight. If the flight planner estimates a longer flight time for the
currently-selected Mission area it will split the mission into two or more
flights.
Default value: 25 min
The third panel, Mission plan actions, includesthe ‘Upload’ button which is used
to upload the resulting mission waypoints to the autopilot. If there are multiple
90
Page 91
eMotion in-depth guide
flights required this button becomes a drop-down list, and you can upload each
flight individually.
Caution: Clicking ‘Upload’ will directly modify the waypoints required for the flight plan in the swinglet CAM. If the drone is flying
towards or around one of these waypoints, its navigation will be affected to reflect the new waypoint parameters.
Clicking the ‘More’ button reveals several more options:
• Load mission area...: Click to load a previously-saved mission area and
parameters from an Auto Flight Planner (.afp) file.
• Save mission area...: Click to save the current mission area and parame-
ters to an Auto Flight Planner (.afp) file. This can be useful for example to
map the same area with different image andmissionparameters,or to save
and restore a large mapping mission that requires multiple flights. Note
that this saves only the mission area shape and location along with the associated mission and image parameters, not the actual list of waypoints
that is then generated or the camera payload model used to calculate the
mission plan.
• Load last used mission area: Clicking will load the last mission area that
was successfully uploaded to a swinglet CAM autopilot, whether it was a
real or simulated one. This option is useful when you want to repeat your
last mission and did not explicitly use the ‘Save mission area...’ button.
• Load mission area from KML file: Use this option to load a polygonal mis-
sion area directly froma KML file (producedin Google EarthTMfor example).
• Load mission area from map object: Use this option to load a polygonal
mission area from a previously-imported map object (see section ‘Toolbar’
on page 71).
• Reset mission area: Clicking will resetthe missionarea to the defaultrect-
angular size and repositionit in the centre of theMap Area. It willalso reset
91
Page 92
Advanced functionalities
all mapping and mission parameters to their last saved default values³⁶.
• Restore factory settings: Click to restore all the parameters of this tab to
their default settings.
The last panel of this tab displays the characteristics of the flight(s)resulting from
the selected image parameters:
• Number offlights: The resulting number offlightsthatmust be performed
to cover the chosen mission area. If the mission area cannot be mapped in
a single flight, eMotion will split it into the minimum possible number of
flights. The estimated distance that can be covered in a flight is calculated
assuming a fully charged battery and an accurate wind estimate.
• Flight time: This is the estimated flight time for each of the flights.
• Total flight distance: The total distancethat willbe flown during all of the
flights.
• Total ground coverage: The total area that will be mapped during all of
the flights.
• Number of flight lines: The total number of flight lines in the mission
phase of the flight plan, not including flight lines to and from the Take-off
or landing locations. The second number represents the flight lines perpendicular to the first number.
• Flight lines spacing: The required distance between parallel flight lines,
calculated using the Lateral overlap and Ground resolution parameters.
³⁶ Default values for mapping and mission parameters are set by clicking the ‘Save parameters as de-
fault’ button.
92
Page 93
eMotion in-depth guide
Note: If the flight line spacing is low enough to cause your drone to
overshoot the beginning of a flight line, eMotion will automatically
switch to an alternating flight line pattern. Your drone will fly along
every other flight line, then return to fill in the gaps. If the spacing
becomes too small even for an alternate flight lines, a will appear
beside this parameter to indicate the warning. You can remove this
warning by decreasing the Lateral overlap or the Ground resolution.
• Mean flight lines altitude above elevation data: Mean altitude differ-
ence between all flight lines and the ground altitude, based on the topmost elevation data layer (3D flight planning only).
• Max flight lines altitude above elevation data: Maximum altitude dif-
ference between a flight line and the ground altitude, based on the topmost elevation data layer (3D flight planning only).
• Min flight lines altitude above elevation data: Minimum altitude differ-
ence between a flight line and the ground altitude, based on the top-most
elevation data layer (3D flight planning only).
• Distance between photos: The required distance between each consec-
utive photo taken in the same flight line, calculated using the Longitudinal
overlap, Ground resolution and Camera model parameters. The wind also
has an influence as the ground speed increases with back wind.
Note: The swinglet CAM has a minimum distance between photos
that depends on the wind speed and direction. If the calculated distance that is too short will be indicated witha icon. This is not critical for the flight, butit may reduce the longitudinal overlapof theimages. Consider reducing the ground resolution (flyhigher) to achieve
the selected longitudinal overlap, or reduce the longitude overlap itself to remove this notice.
• Single image coverage: The estimated ground area covered by a single
93
Page 94
Advanced functionalities
image, based on the Altitude over take-off location parameter (assuming
flat terrain).
• Number of waypoints: The total number of waypoints to cover the mis-
sion area.
• Elevation data sources: The elevation data sources being used to calcu-
late the altitudes of the waypoints. This can beeither thedefault ‘Improved
SRTM’ within eMotion or imported custom data sets, depending on which
one is activatedand is at the topof the list in the‘Elevation data’Preference
pane.
The flight characteristics are updated automatically as you modify the mission
area in the Map Area or the parameters in the first panel.
94
Page 95
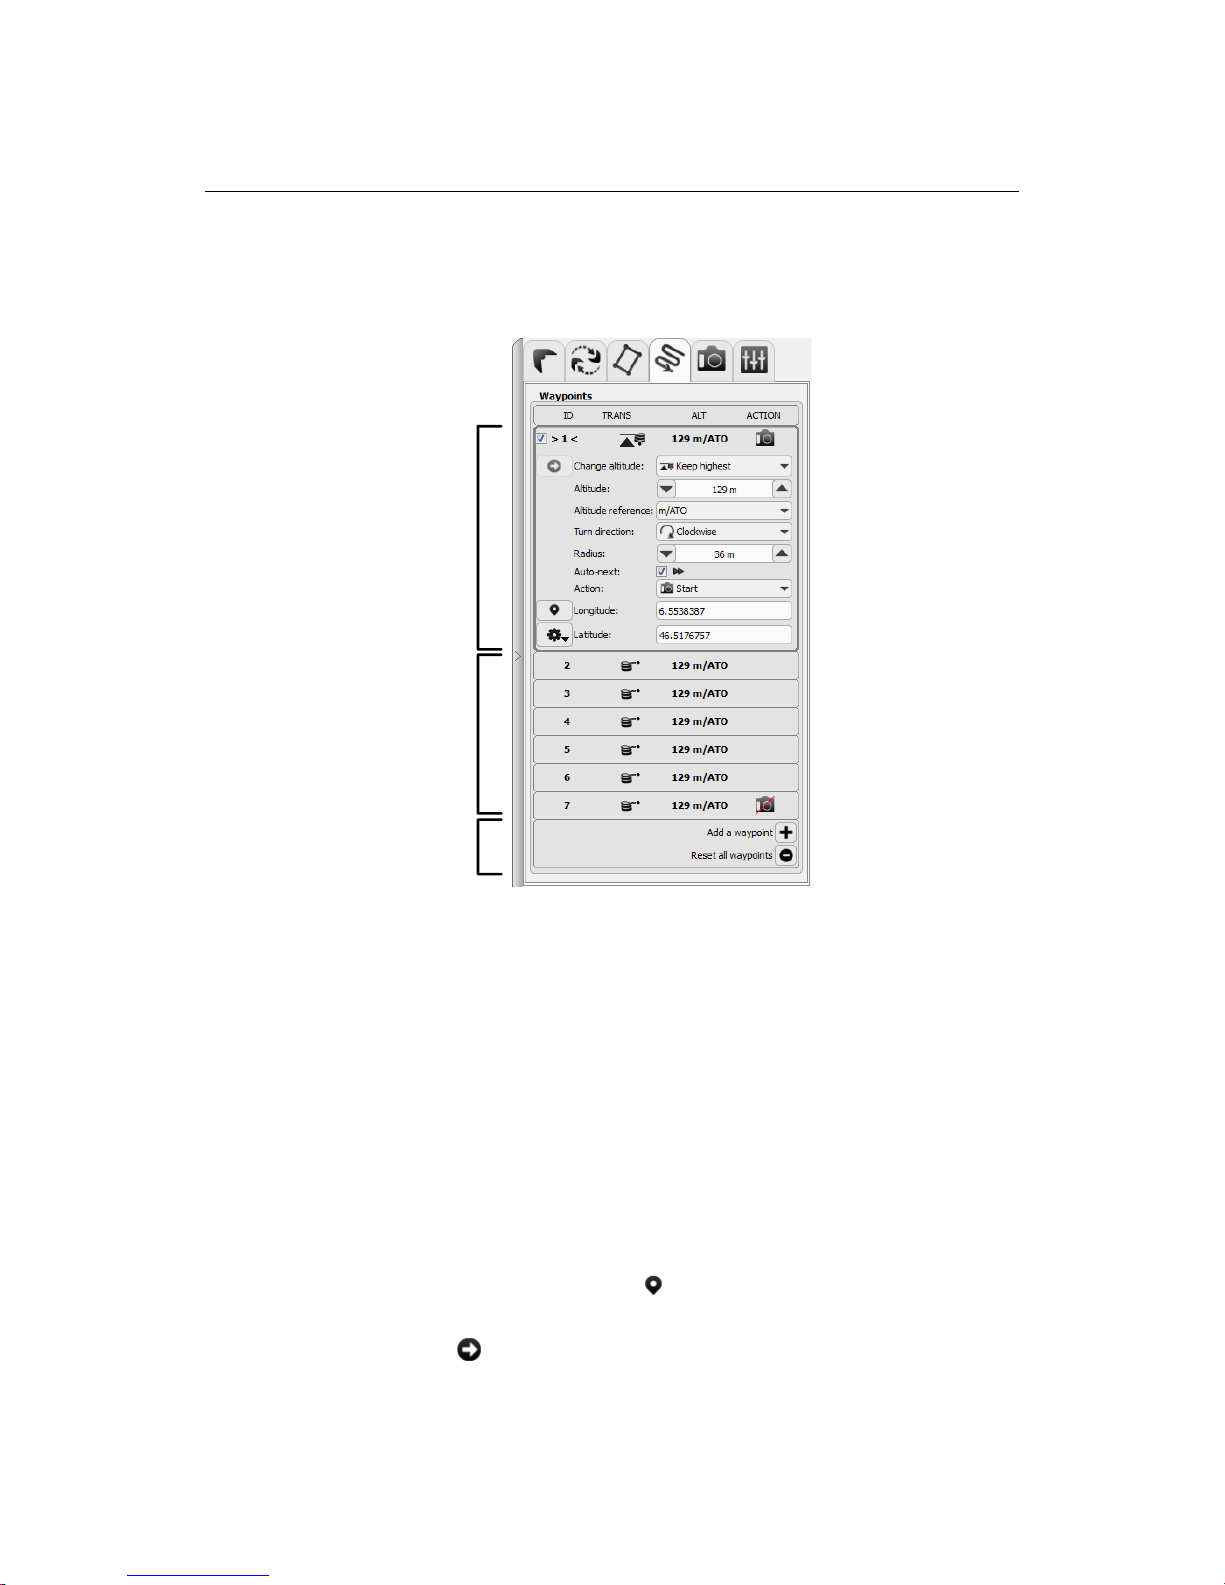
eMotion in-depth guide
5.7 Mission Waypoints tab
Selected mission
waypoint
parameters
Remaining
mission
waypoints
Add or reset
waypoints
The Mission Waypoints tab contains a list of all mission waypoints currently on
the drone autopilot. It can be used for finer control of individual waypoints in the
current mission. The list of waypoints displays the ID, Change altitude parameter,
Altitude and Action related to each mission waypoint.
Clicking on amission waypoint in thelist or in the Map Area will expand the panel
to display all the parameters related to that waypoint. These parameters are explained in detail in section ‘Waypoints and their properties’ on page 50. Changes
made to the selected waypoint are sent to the drone immediately after selecting
an item in the popup menu or upon hitting the ‘Enter’ key in the text fields. You
can reposition thewaypoint by clicking the button and then clicking at the desired position in the Map Area. You can make the selected waypoint the current
waypoint by clicking the button.
95
Page 96
Advanced functionalities
Caution: Any change to the waypoints or their parameters are directly sent to the drone and may therefore impact its flight behaviour.
Werecommend that you take great care before modifyingwaypoints
while the drone is in flight.
You can add new waypoints by clicking the button or by right-clicking on the
Map Area and selecting ‘Add waypoint here’. Clicking the button will remove
all mission waypoints from the drone.
Note: All modifications made to the waypoint list will be lost when
the drone is switchedoff,unless the list is explicitly saved into the autopilot using the‘Save flight plan indrone’button in the Setup Phase
tab (see Section ‘Setup Phase tab’ on page 82).
96
Page 97
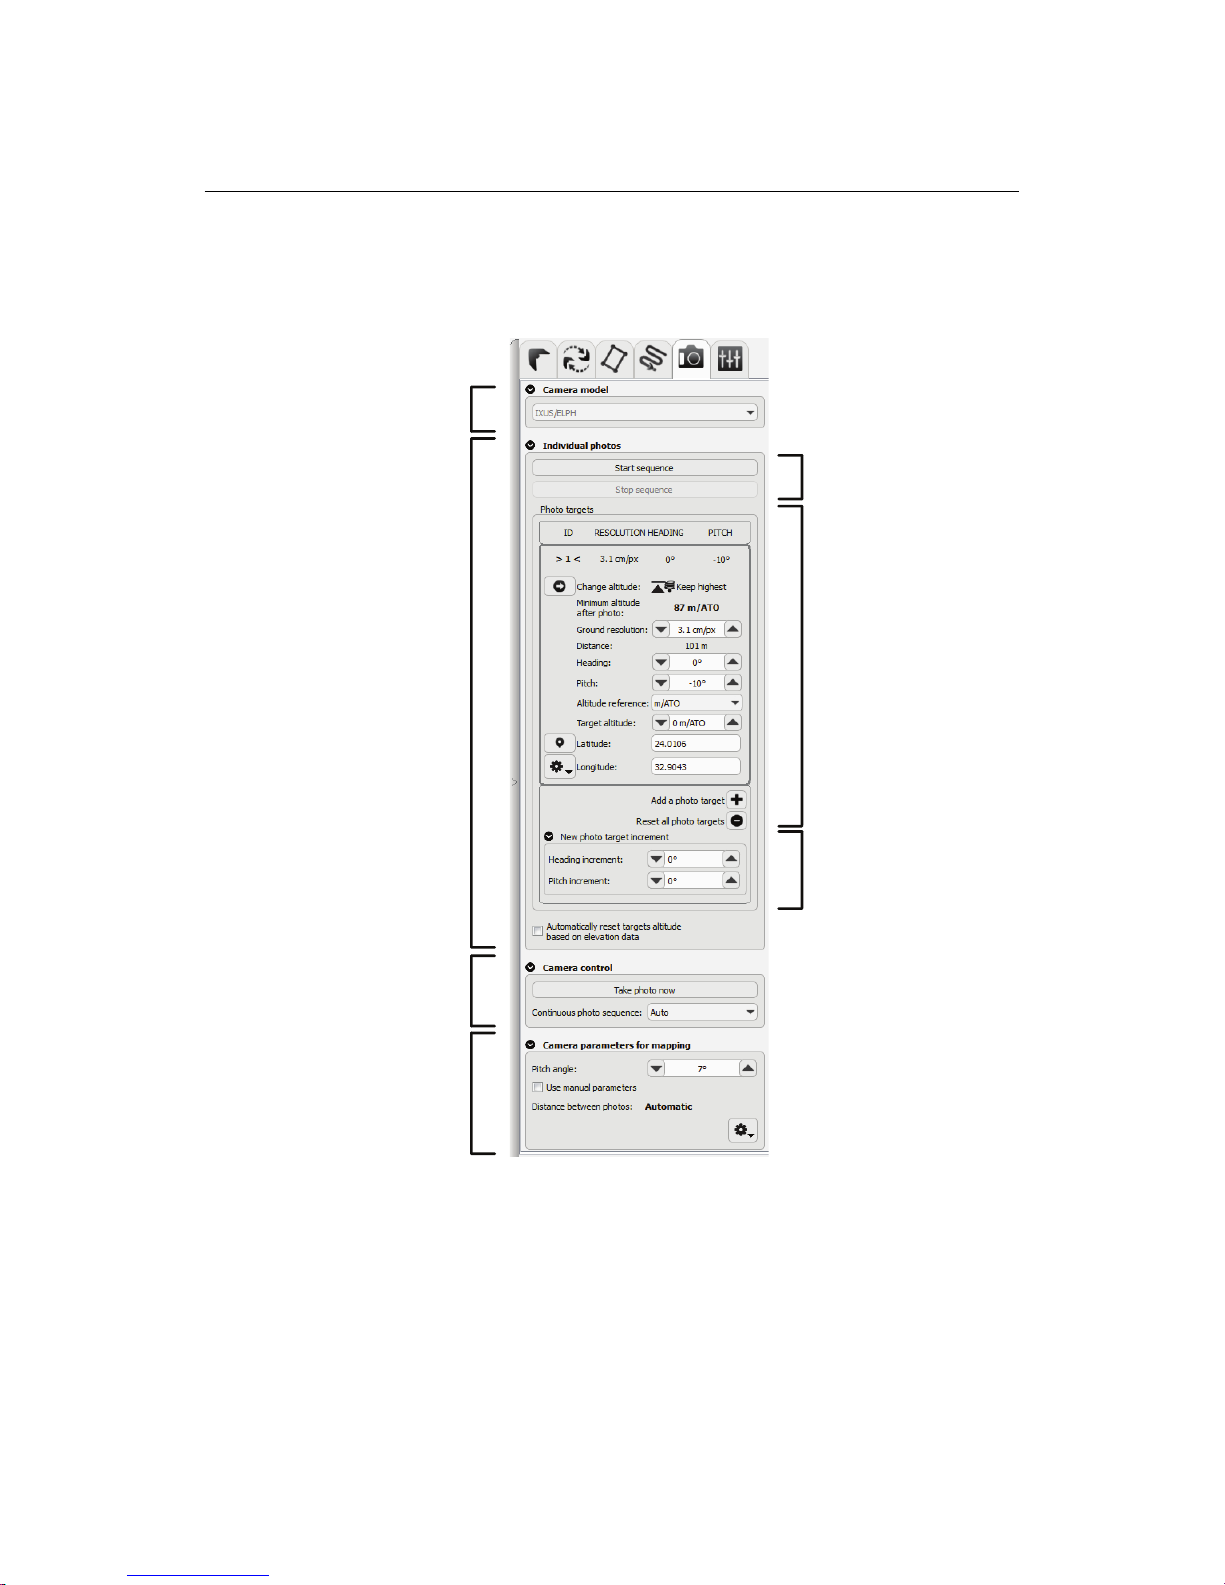
eMotion in-depth guide
5.8 Camera tab
Photo sequence
control
Camera control
Camera parameters
for mapping
Camera model
Photo targets
New photo
target increment
Individual photos
The camera tab is an advanced tab that can be used to precisely control the functioning of the camera. It also contains controls for taking oblique imagery. It is
split into several sections: ‘Camera model’, ‘Photo targets’, ‘Camera control’, and
‘Camera parameters for mapping’.
97
Page 98
Advanced functionalities
The ‘Cameramodel’ section is usedto definethe cameraor payloadcurrently connected to the swinglet CAM. The list contains all payloads currently supported on
the swinglet CAM.
The ‘Photo targets’ section allows you to program a set of photo targets that the
drone will capture with an oblique angle. You can define a photo target location,
distance to the object and the heading and pitch of the photograph. The drone
will then automatically calculate a flight plan in order to capture the photo with
the desired parameters.
• Photo sequence control: Clicking the ‘Start sequence’ button will send
the drone to the first photo target location and subsequently take images
of all thephototargetscurrently in the ‘Photo targets’list. Clickingthe‘Stop
sequence’ will send the drone back to the Home waypoint.
• Photo targets: This panel contains the list of photo targets to be taken in
a sequence. Clicking the button will add a new photo target. You can
set the location by using the cross-hairs and clicking in the Map Area. By
default, the location of a new photo target is the same as the previous one
in the list. Clicking the will remove all photo targets from the sequence
list. Each photo target has the following properties:
– Change altitude: The way the drone transitions to the altitude of
the current photo target. This parameter is set to ‘Keep highest’ for
all photo targets and cannot be modified.
– Minimum altitude after photo: This is the calculated minimum al-
titude the drone will reach at the end of a photo capture manoeuvre,
based on the desired ground resolution.
– Ground resolution: The desired ground resolution in the centre of
the image that will be pointed at the photo target position.
– Distance: The calculated straight-line distance between the drone
and the photo target, and the defined pitch angle. For a given distance, as the pitch angle increases, the distance to the ground decreases.
– Heading: The heading angle with respect to North of the photo tar-
get.
98
Page 99
eMotion in-depth guide
– Pitch: The pitch angle with respect to vertical of the photo target.
– Altitude reference: The altitude reference of the photo target alti-
tude, either ATO or AMSL.
– Target altitude: The altitude of the photo target.
– Position(Coordinate): Theprecise latitude and longitudeofthecen-
tre of the waypoint.
• New photo target increment: This panel makes it easier to make a se-
ries of oblique photos of the same target with a regular angle increment in
order to aid reconstruction of a 3D model. Every new Photo target that is
added using the button will be placed at the same location as the previous one, but with an increment in heading and pitch angles defined by the
‘Heading increment’ and ‘Pitch increment’ parameters, respectively.
Default value: Heading increment: 0◦, Pitch increment: 0
◦
• Automatically reset target altitude based on elevation data: Check
this box to use elevation data to set the absolute photo target altitudes.
If this box is unchecked, photo targets are presumed to be at the same altitude as the take-off location.
Default value: disabled
The ‘Camera control’ section has the following functions:
• Take photo now: Clicking this button will send a command to the drone
to take a single picture at its current location. This command can be sent
during the mission phase of a flight plan.
Note: The ‘Take photo now’ button hasno effect during Take-off, Circular landing and Emergency landing modes.
• Continuous photo sequence: These radio buttons define how the drone
is taking images. When the default option ‘Auto’ is selected the drone will
start and stop continuous photo shooting based on the actions associated
99
Page 100
Advanced functionalities
with mission waypoints. Selecting ‘On’ overrides waypoint actions and enables continuous shooting. Conversely, selecting ‘Off’ will override waypoint actions and disable continuous shooting.
Default value: Auto
The ‘Camera parameters for mapping’ section is used to define detailed parameters related to the camera and has the following functions:
• Pitch angle: By default the swinglet CAM takes images at a default esti-
mated pitch angle of 10◦relative to the horizon. This angle provides the
best compromise between image quality and flight endurance. In some
cases, however, you may wish to change this value to suit your imaging
needs.
Increasing this angle to 15◦provides a slightly more perspective view of
a building. Note, however, that a higher pitch angle will cause the drone
to slow down every time it takes an image, losing altitude and decreasing
flight time and longitudinal overlap.
Decrease the pitch angle down to 0◦can capture more vertical images of
the ground if mapping precision at low altitudes is of utmost importance.
However, decreasing this angle will cause the drone to lose altitude with
each image taken, requiring it to return to the target altitude before taking
another image, once again decreasing both flight time and longitudinal
overlap between images.
Default value: 10
◦
• Distance between photos: Check the ‘Use manual parameters’ box to
manually set the distance between photos in the direction of flight. This
option may be used to override the automatic settings based on altitude
and longitudinal overlap.
Default value: Unchecked, Distance between photos: Automatic
Note: Depending on the altitude and the wind the desired distance
between images may not always be achievable. The minimum distance with no wind and at sea level is around 35-40 m.
100
 Loading...