

Page 1
Product Manual
NL35 Series FC
ST3500071FC
ST3400071FC
100343673
Rev . D
August 2007
Page 2
©2007, Seagate Technology LLC All rights reserved.
Publication number: 100343673, Rev. D
August 2007
Seagate, Seagate Technology and the Wave logo are registered trademarks of Seagate Technology LLC
in the United States and/or other countries. NL35 Series, SeaTools and SeaTDD are either trademarks or
registered trademarks of Seagate Technology LLC or one of its affiliated companies in the United States
and/or other countries. All other trademarks or registered trademarks are the property of their respective
owners.
One gigabyte, or GB, equals one billion bytes when referring to hard drive capacity. Accessible capacity
may vary depending on operating environment and formatting. Quantitative usage examples for various
applications are for illustrative purposes. Actual quantities will vary based on various factors, including file
size, file format, features and application software. Seagate reserves the right to change, without notice,
product offerings or specifications.
Page 3
NL35 Series FC Product Manual, Rev. D
iii
Contents
1.0 Scope. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 1
2.0 Applicable standards and reference documentation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 3
2.1 Standards . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 3
2.1.1 Electromagnetic compatibility. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 3
2.1.2 Electromagnetic susceptibility . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 3
2.2 Electromagnetic compliance . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 4
2.3 Environmental protection. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 4
2.4 Reference documents . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 5
3.0 General description . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 7
3.1 Standard features . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
3.2 Media description . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
3.3 Performance . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
3.4 Reliability. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
3.5 Formatted capacities. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
3.5.1 Programmable drive capacity. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
3.6 Factory-installed accessories . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
3.7 Factory-installed options . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
3.8 User-installed accessories. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
4.0 Performance characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
4.1 Internal drive characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
4.2 Seek performance characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
4.2.1 Access time [4]. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
4.2.2 Format command execution time (in minutes). . . . . . . . . . . . . . . . . . . . . . . . . . 11
4.2.3 Generalized performance characteristics. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 12
4.3 Start/stop time . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
4.4 Prefetch/multi-segmented cache control. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
4.5 Cache operation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
4.5.1 Caching write data. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
4.5.2 Prefetch operation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
4.5.3 Optimizing cache performance for desktop and server applications . . . . . . . . . 15
5.0 Reliability specifications . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 17
5.1 Error rates . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 17
5.1.1 Recoverable Errors . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 18
5.1.2 Unrecoverable errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 18
5.1.3 Seek errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 18
5.1.4 Interface errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 18
5.2 Reliability and service . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 18
5.2.1 Mean Time Between Failure (MTBF). . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 19
5.2.2 Preventive maintenance. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 19
5.2.3 Hot plugging the drive . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 19
5.2.4 S.M.A.R.T. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 20
5.2.5 Thermal monitor. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 21
5.2.6 Drive Self Test (DST). . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 22
5.2.7 Product warranty . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 24
6.0 Physical/electrical specifications . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 25
6.1 AC power requirements. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 25
6.2 DC power requirements. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 25
6.2.1 Conducted noise immunity. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 26
6.2.2 Power sequencing . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 26
6.3 Power dissipation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 27
Page 4
iv
NL35 Series FC Product Manual, Rev. D
6.4 Environmental limits. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 28
6.4.1 Temperature. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 28
6.4.2 Relative humidity . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 28
6.4.3 Effective altitude (sea level) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 28
6.4.4 Shock and vibration . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 29
6.4.5 Air cleanliness . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 31
6.4.6 Corrosive environment. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 32
6.4.7 Acoustics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 32
6.4.8 Electromagnetic susceptibility . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 32
6.5 Mechanical specifications . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 33
7.0 Defect and error management. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 35
7.1 Drive internal defects/errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 35
7.2 Drive error recovery procedures . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 35
7.3 FC-AL system errors . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
7.4 Background Media Scan . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
7.4.1 Media Pre-Scan . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
8.0 Installation. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 39
8.1 Drive ID/option selection . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 39
8.2 Drive orientation. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 39
8.3 Cooling. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 40
8.4 Drive mounting. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 41
8.5 Grounding . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 41
9.0 Interface requirements . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 43
9.1 FC-AL features. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 43
9.1.1 Fibre Channel link service frames . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 43
9.1.2 Fibre Channel task management functions . . . . . . . . . . . . . . . . . . . . . . . . . . . . 44
9.1.3 Fibre Channel task management responses . . . . . . . . . . . . . . . . . . . . . . . . . . . 44
9.1.4 Fibre Channel port login. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 45
9.1.5 Fibre Channel port login accept . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 46
9.1.6 Fibre Channel Process Login. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 46
9.1.7 Fibre Channel Process Login Accept. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 47
9.1.8 Fibre Channel fabric login. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 47
9.1.9 Fibre Channel fabric accept login. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 48
9.1.10 Fibre Channel Arbitrated Loop options. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 49
9.2 Dual port support . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 49
9.3 SCSI commands supported. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 50
9.3.1 Inquiry data. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 55
9.3.2 Mode Sense data. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 55
9.4 Miscellaneous operating features and conditions . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 59
9.5 FC-AL physical interface . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 60
9.5.1 Physical characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 60
9.5.2 Connector requirements. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 61
9.5.3 Electrical description. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 61
9.5.4 Pin descriptions . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 62
9.5.5 FC-AL transmitters and receivers. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 63
9.5.6 Power . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 63
9.5.7 Fault LED Out. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 63
9.5.8 Active LED Out. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 64
9.5.9 Enable port bypass signals. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 64
9.5.10 Motor start controls. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 65
9.5.11 SEL_6 through SEL_0 ID lines. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 65
9.5.12 Device control codes . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 67
9.6 Signal characteristics. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 67
Page 5
NL35 Series FC Product Manual, Rev. D
v
9.6.1 TTL input characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 67
9.6.2 LED driver signals . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 68
9.6.3 Differential PECL output. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 68
9.6.4 Differential PECL input. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 68
10.0 Seagate Technology support services. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 71
Page 6
vi
NL35 Series FC Product Manual, Rev. D
Page 7
NL35 Series FC Product Manual, Rev. D
vii
List of Figures
Figure 1. NL35 Series family disc drive . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 1
Figure 2. DC current and power vs. input/output operations per second (1 Gbit). . . . . . . . . . . . . . . . . 27
Figure 3. DC current and power vs. input/output operations per second (2 Gbit). . . . . . . . . . . . . . . . . 27
Figure 4. Location of the HDA Temperature check point . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 28
Figure 5. Recommended mounting . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 30
Figure 6. Mounting configuration dimensions. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 33
Figure 7. Air flow. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 40
Figure 8. Physical interface . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 60
Figure 9. Port bypass circuit physical interconnect. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 60
Figure 10. FC-AL SCA device connector dimensions. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 61
Figure 11. FC-AL transmitters and receivers . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 63
Figure 12. Transmit eye diagram . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 68
Figure 13. Receive eye diagram . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 69
Page 8
viii
NL35 Series FC Product Manual, Rev. D
Page 9
NL35 Series FC Product Manual, Rev. D
1
1.0 Scope
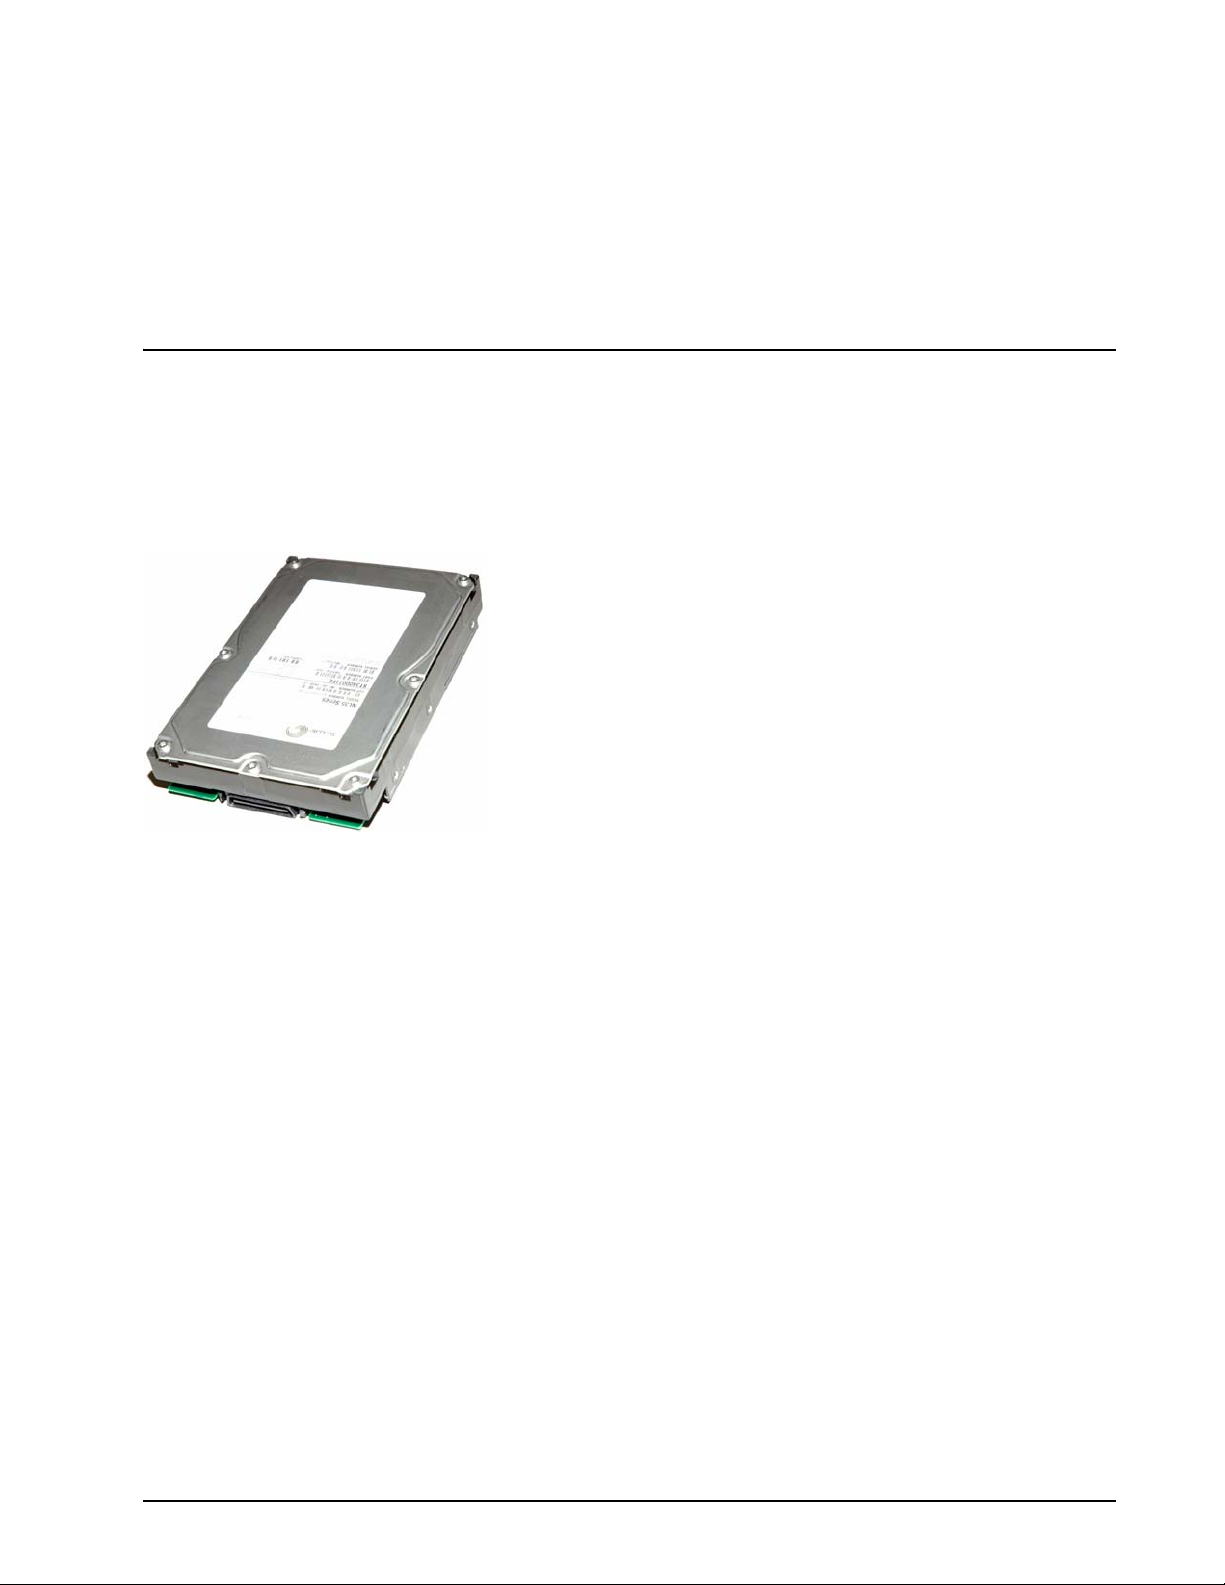
This manual describes Seagate Technology® LLC, NL35 Series (Fibre Channel) disc drives.
NL35 Series drives support the Fibre Channel Arbitrated Loop and SCSI Fibre Channel Protocol specifications
to the extent described in this manual. The Fibre Channel Interface Manual (part number 77767496) describes
the general Fibre Channel Arbitrated Loop characteristics of this and other Seagate Fibre Channel drives.
Figure 1. NL35 Series family disc drive
Page 10
2
NL35 Series FC Product Manual, Rev. D
Page 11
NL35 Series FC Product Manual, Rev. D
3
2.0 Applicable standards and reference documentation
The drive has been d evelope d as a system p eriphe ral to the hig hest st and ards of desig n and constru c tion. The
drive depends upon its host equipment to provide adequate power and environment in order to achieve optimum performance and compliance with applicable industry and governmental regulations. Special attention
must be given in the areas of safety, power distribution, shielding, audi ble noise con trol , an d tempe ratu re reg ulation. In particular, the drive must be securely mounted in order to guarantee the specified performance characteristics. Mounting by bottom holes must meet the requirements of Section 8.4.
2.1 Standards
The NL35 Series family complies with Seagate standards as noted in the appropriate sections of this manual
and the Seagate Fibre Channel Interface Manual, part number 77767496.
The NL35 Series disc drive is a UL recognized component per UL1950, CSA certified to CAN/CSA C22.2 No.
950-95, and VDE or TUV certified to EN60950.
2.1.1 E lect roma gn etic compatibility
The drive, as delivered, is designed for system integration and installation into a suitable enclosure prior to
use. As such the drive is supplied as a subassembly and is not subject to Subpart B of Part 15 of the FCC
Rules and Regulations nor the Radio Interference Regulations of the Canadian Department of Communications.
The design characteristics of the drive serve to minimize radiation when installed in an enclosure that provides
reasonable shield ing. As such, t he dr ive is cap able of me eting th e C lass B l imit s of the FC C Rules a nd R eg ulations of the Canadian Department of Communications when properly packaged. However, it is the user’s
responsibility to assure that the drive meets the appropriate EMI requirements in their system. Shielded I/O
cables may be required if the enclosure does not provide adequate shielding. If the I/O cables are external to
the enclosure, shielded cabl es sh ould be u sed, wi th the shields gr ounde d to the enclosur e and to the host co ntroller.
2.1.2 Electromagn etic susc ept ibili ty
As a component assembly, the drive is not required to meet any susceptibility performance requirements. It is
the responsibility of those integrating the drive within their systems to perform those tests required and design
their system to ensure that equipment operating in the same system as the drive or external to the system
does not adversely affect the performance of the drive. See Section Table 11, DC power requirements.
Page 12
4
NL35 Series FC Product Manual, Rev. D
2.2 Electroma gnetic compliance
Seagate uses an independent laboratory to confirm compliance with the directives/standards for CE Marking
and C-Tick Marking. T he dr ive was tested in a r epre sent ative system for typica l applications. The select ed system represents the most popular characteristics for test platforms. The system configurations include:
• Typical current use microprocessor
• 3.5-inch floppy disc drive
• Keyboard
• Monitor/display
• Printer
• External modem
• Mouse
Although the test system with th is Seag ate mo del comp lies with the dir ectives/st and ards, we cannot gu aran tee
that all systems will comply. The computer manufacturer or system integrator shall confirm EMC compliance
and provide the appropriate marking for their product.
Electromagnetic compliance for the European Union
If this model has the CE Marking it complies with the European Union requirements of the Electromagnetic
Compatibility Directive 89/336/EEC of 03 May 1989 as amended by Directive 92/31/EEC of 28 April 1992 and
Directive 93/68/EEC of 22 July 1993.
Australian C-Tick
If this model has the C-Tick Marking it complies with the Australia/New Zealand Standard AS/NZS3548 1995
and meets the Electromagnetic Compatibility (EMC) Framework requirements of Australia’s Spectrum Management Agency (SMA).
Korean MIC
If this model has the Korean Min ist ry of Infor mat ion and Com munication (MIC) logo, it complie s with par agr aph
1 of Article 11 of the Electromagnetic Compatibility (EMC) Control Regulation and meets the Electromagnetic
Compatibility Framework requirements of the Radio Research Laboratory (RRL) Ministry of Information and
Communication Republic of Korea.
Taiwanese BSMI
If this model has the Chin ese N ation al Standard (CNS) 13438 marking, it co mplies w ith Chi n ese Nationa l Standard (CNS) 13438 and meets the Electromagnetic Compatibility (EMC) Framework requirements of the Taiwanese Bureau of Standards, Metrology, and Inspection (BSMI).
2.3 Environmental protection
Seagate designs its products to meet environmental protection requirements worldwide, including regulations
restricting certain chemica l subst ances .
European Union Restriction of Hazardous Substances (RoHS)
A new law, the European Union Restriction of Hazardous Substances (RoHS) directive, will restrict the presence of chemical substances, including Lead (Pb), in electronic products effective July 2006. The directive’s
requirements have not been finalized. This drive is manufactured with components and materials that are
expected to comply with the RoHS directive when the directive takes effect.
Page 13
NL35 Series FC Product Manual, Rev. D
5
2.4 Reference documents
NL35 Series FC Installation Guide Seagate part number: 100343674
Fibre Channel Interface Manual Seagate part number: 77767496
ANSI Fibre Channel Documents
X3.230-1994 FC Physical and Signaling Interface (FC-PH)
X3.297.1997 FC-PH-2 Fibre Channel Physical and Signaling Interface-2
X3.303.1998 FC-PH-3 Fibre Channel Physical and Signaling Interface-3
X3.272-1996 FC Arbitrated Loop (FC-AL)
X3.269-1996 Fibre Channel Protocol for SCSI (FCP)
NCITS TR-19 Private Loop SCSI Direct Attach (PLDA)
NCITS TR-20 Fabric Loop Attachment (FC-FLA)
SFF-8045 Specification for 40-pin SCA-2 Connector with Parallel Selection
SFF-8067 Specification for 40-pin SCA-2 Connector with
Bidirectional Enclosure Services Interface
ANSI Small Computer System Interface (SCSI) Documents
X3.131-1994 (SCSI-2)
X3.270-1996 (SCSI-3) Architecture Model
NCITS 305-199X (SCSI-3) Enclosure Services
Specification for Acoustic Test
Requirement and Procedures Seagate part number: 30553-001
Package Test Specification Seagate P/N 30190-001 (under 100 lb.)
Package Test Specification Seagate P/N 30191-001 (over 100 lb.)
In case of conflict between this document and any referenced document, this document takes precedence.
Page 14
6
NL35 Series FC Product Manual, Rev. D
Page 15
NL35 Series FC Product Manual, Rev. D
7
3.0 General description
NL35 Series drives combine Tunneling Magnetoresistive (TMR) heads and a Fibre Channel interface to provide high performance, high capacity data storage for a variety of systems including engineering workstations,
network servers, mainframes, and supercomputers.
NL35 Series drives support the Fibre Channel Arbitrated Loop (FC-AL) and SCSI Fibre Channel Protocol as
described in the ANSI specifications, this document, and the Fibre Channel Interface Manual (part number
77767496) which describes the general interface characteristics of this drive. NL35 Series drives are classified
as intelligent peripherals and provide level 2 conformance (highest level) with the ANSI SCSI standard.
Never disassemble the HDA and do not attempt to service items in the sealed enclosure (heads, media, actuator, etc.) as this requires special facilities. The drive contains no parts replaceable by the user and opening
the HDA for any reason voids your warranty.
NL35 Series drives use a dedi ca ted lan ding zon e at th e i nnermost r adi us o f the m edia to eli minat e the p ossibil ity of destroying or degrading data by landing in the data zone. The drive automatically goes to the landing
zone when power is removed.
An automatic shipping lock prevents potential damage to the heads and discs that results from movement during shipping and handling. The shipping lock automatically disengages when power is applied to the drive and
the head load process begins.
A high-performance actuator assembly with a low-inertia, balanced, patented, straight arm design provides
excellent performance with minimal power dissipation.
Page 16
8
NL35 Series FC Product Manual, Rev. D
3.1 Standard featu re s
NL35 Series drives have the following standard features:
• Integrated dual port FC-AL controller
• Concurrent dual port transfers
• Support for FC arbitrated loop, private and public attachment
• Differential copper FC drivers and receivers
• Downloadable firmware using the FC-AL interface
• Supports SCSI enclosure services via interface connector
• 64-deep task set (queue)
• Supports up to 32 initiators
• Drive selection ID and configuration options are set on the FC -AL ba ckpanel or th roug h inter face co mma nds.
Jumpers are not used on the drive.
• Fibre Channel worldwide name uniquely identifies the drive and each port
• User-selectable logical block size (512, 520, 524 or 528 bytes per logical block)
• Selectable frame sizes from 256 to 2,112 bytes
• Industry standard 3.5-inch low profile form factor dimensions
• Programmable logical block reallocation scheme
• Flawed logical block reallocation at format time
• Programmable auto write and read reallocation
• Reed-Solomon error correction code
• Sealed head and disc assembly (HDA)
• No preventive maintenance or adjustments required
• Dedicated head landing zone
• Automatic shipping lock
• Embedded Grey Code track address and servo wedge address to eliminate seek errors
• Self-diagnostics performed at power on
• 1:1 interleave
• Zone bit recording (ZBR)
• Vertical, horizontal, or top down mounting
• Dynamic spindle brake
• 8,192 Kbyte data buffer. See Section 4.5.
• Drive Self Test (DST)
• BackGround Media Scan (BGMS)
• Data Integrity Check
• Power Save
• Embedded servo design
• Reallocation of defects on command (Post Format)
• Fibre Channel interface transports SCSI protocol
Page 17
NL35 Series FC Product Manual, Rev. D
9
3.2 Media desc ription
The media used on the drive has an aluminum substrate coated with a thin film magnetic material, overcoated
with a proprietary protective layer for improved durability and environmental protection.
3.3 Performance
• Programmable multi-segmentable cache buffer
• 200 Mbytes/sec maximum instantaneous data transfers per port
• 7K RPM spindle; average latency = 4.17 msec
• Command queuing of up to 64 commands
• Background processing of queue
• Supports start and stop commands
3.4 Reliability
• 1,000,000 hours MTBF (Mean Time Between Failures)
• LSI circuitry
• Balanced low mass rotary voice coil actuator
• Self-Monitoring Analysis and Reporting Technology (S.M.A.R.T.)
• Dithering
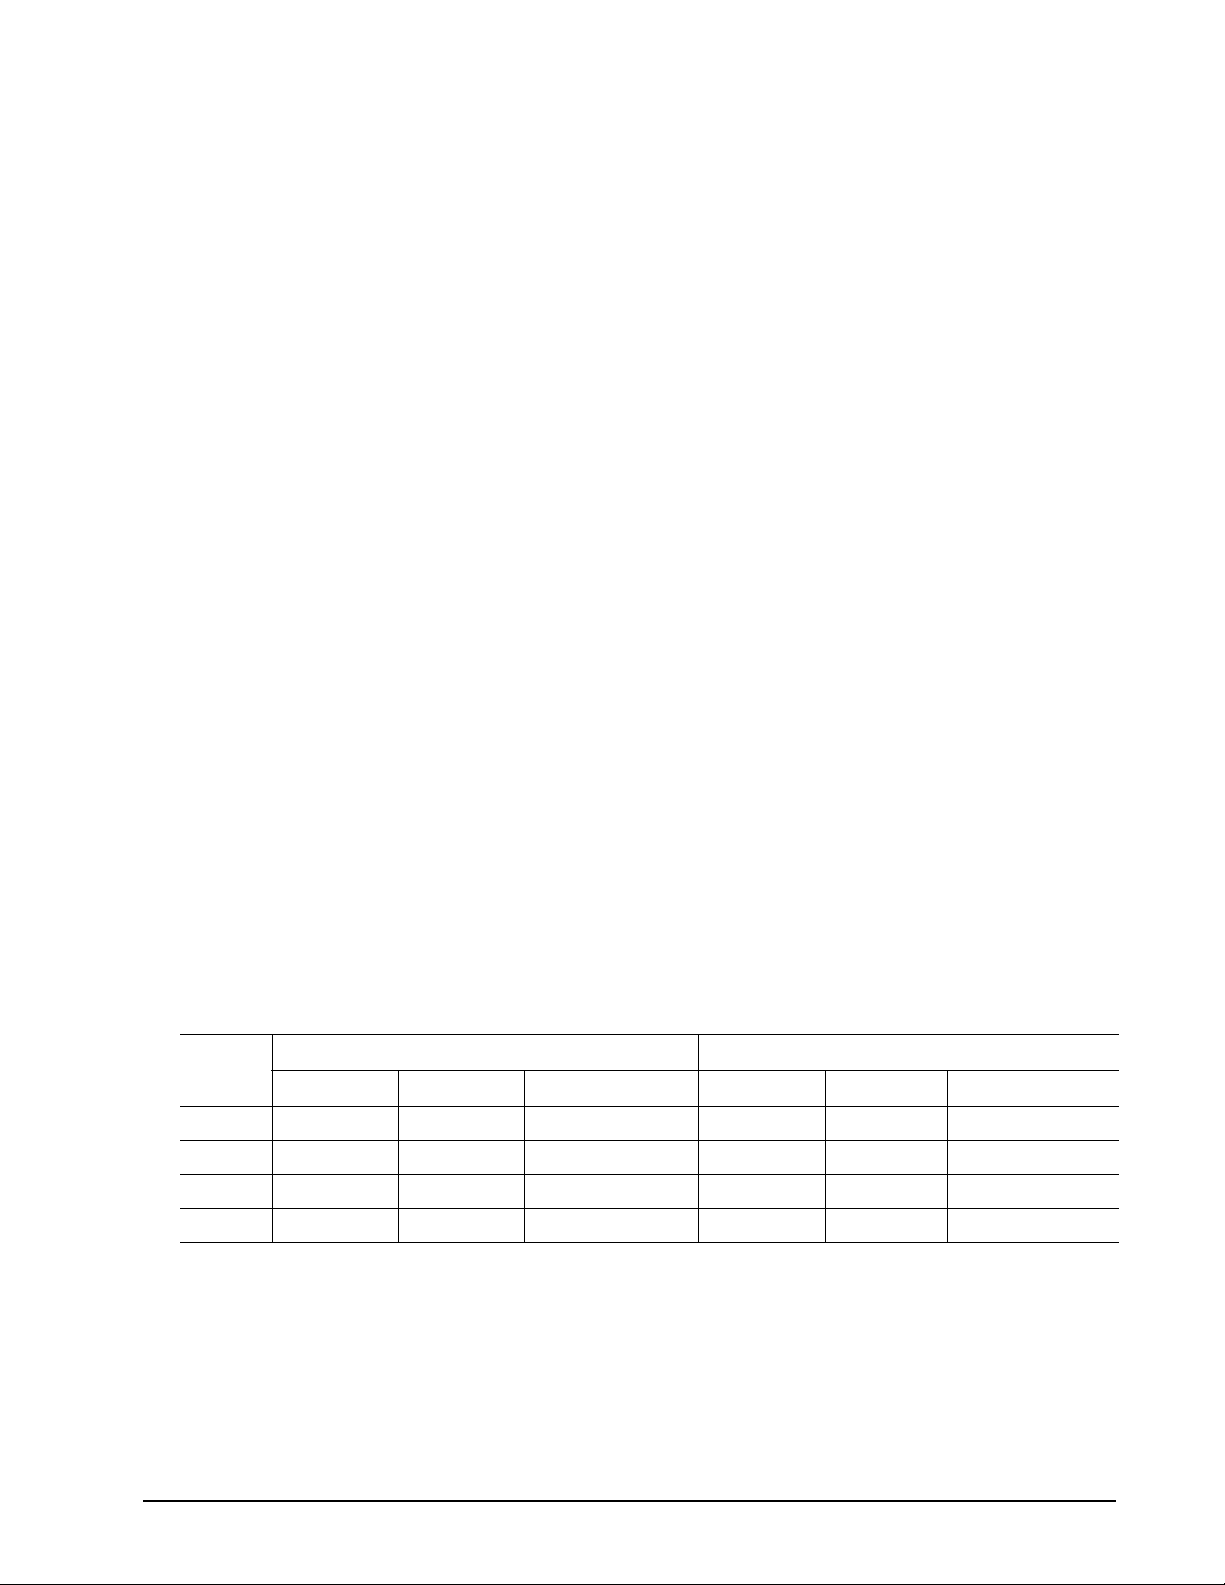
3.5 Formatted ca pacities
St an dard OEM mo del s ar e formatte d to 512 bytes per block. The sector size is sel ect ab le at fo rma t time. Users
having the necessary equipment may modify the data block size before issuing a format command and obtain
different formatted capacities than those listed.
For 2 gigabit operation, sector sizes must be divisible by 8.
To provide a stable target capacity environment and at the same time provide users with flexibility if they
choose, Seagate recommends product planning in one of two modes:
1. Seagate designs specify cap acity po i nt s at cert ain sect or si zes tha t Seagate gu ara ntees cur ren t and futu re
products will meet. We recommend customers use this capacity in their project planning, as it ensures a
stable operating point with backward and forward compatibility from generation to generation. The current
guaranteed operating points for this product are:
Sector
Size
2. Seagate drives also may be used at the maxi mu m available cap acity at a given secto r size, but the excess
capacity above the guaranteed level will vary between 7K, 10K and 15K families and from generation to
generation, depending on how each sector size actually formats out for zone frequencies and splits over
servo bursts. This added capacity potential may range from 0.1 to 1.3 percent above the guaranteed
capacities listed abo ve. U sing the drives in this manner give s the abso lute m aximum cap a c ity pot ential , but
the user must determine if the extra capacity potential is useful, or whether their assurance of backward
and forward compatibility takes precedence.
ST3500071FC ST3400071FC
Decimal Hex Capacity (bytes) Decimal Hex Capacity (bytes)
512 976562500 3A352944 500,000,000,000 781250000 2E90EDD0 400,000,000,000
520 961538465 394FE9A1 500,000,001,800 769230777 2DD987B9 400,000,004,040
524 941486281 381DF0C9 493,338,811,244 752213841 2CD5DF51 394,160,052,684
528 938165665 37EB45A1 495,351,471,120 749632385 2CAE7B81 395,805,899,280
Page 18
10
NL35 Series FC Product Manual, Rev. D
3.5.1 Programmable drive capacity
Using the Mode Select command, the drive can change its capacity to something less than maximum. See the
Mode Select Parameter List table in the FC Interface Product Manual. Refer to the Parameter list block
descriptor number of blocks field. A value of zero in the number of blocks field indicates that the drive shall not
change the capacity it is currently formatted to have. A number in the number of blocks field that is less than
the maximum number of LBAs changes the total drive capacity to the value in the block descriptor number of
blocks field. A value greater than the maximum number of LBAs is rounded down to the maximum capacity.
3.6 Factory -installed acce ssories
OEM standard drives are shipped with the NL35 Series FC Installation Guide (part number 100343674).
3.7 Factory-installed options
Yo u may order the following items which are incorporated at the manufacturing facility d uring production or
packaged before shipping. Some of the options available are (not an exhaustive list of possible options):
• Other capacities can be ordered depending on sparing scheme and sector size requested.
• Single-unit shipping pack. The drive is normally shipped in bulk packaging to provide maximum protection
against transit damage. U nit s shipped individually require add itional pro tection as pr ovided by th e singl e unit
shipping pack. Users planning single unit distribution should specify this option.
• The NL35 Series FC Installation Guide, part number 100343674, is usually included with each standard
OEM drive shipped, but extra copies may be ordered.
• The Safety and Regulatory Agency Specifications, part number 75789512, is usually included with each
standard OEM drive shipped, but extra copies may be ordered.
3.8 User-ins talle d accessorie s
The following accessories are available. All kits may be installed in the field.
• 4 Gbit Fibre Channel Kit, part number 100364396
This kit contains an interposer board which allows the FC connector on the drive to be split into its component parts with one PS (5V, 12V) 4-pin Molex connector and 2 SFP (20-pin, 3.3V) data connectors. This
alows a standard PC power supply and 2 HBA data channels to be connected directly to the drive.
• Single-unit shipping pack.
Page 19
NL35 Series FC Product Manual, Rev. D
11
4.0 Performance characteristics
This section provides detailed information concerning performance-related characteristics and features of
NL35 Series drives.
4.1 Internal drive characteristics
ST3500071FC ST3400071FC
Drive capacity* 500.0 ........................ 400.0........................ ..................Gbytes (formatted, rounded off value)
Read/write data heads 8 ...............................8
Bytes per track 686...........................552........................... ..................Kbytes (average, rounded off values)
Bytes per surface 84.1 ..........................67.7.......................... ..................Mbytes (unformatted, rounded off value)
Tracks per surface (total) 122,712 .................... 122,712.................... ..................Tracks (user accessible)
Tracks per inch 120,000 .................... 120,000.................... ..................TPI
Peak bits per inch 747 ........................... 597........................... ..................KBPI
Internal data rate 411-794 ....................322-669.................... ..................Mbits/sec (variable with zone)
Disc rotation speed 7,200 . ...... ................. 7,200. ....................... ..................rpm (+ 0.5%)
Avg rotational latency 4.17 .......................... 4.17................. ......... ..................msec
* One Gbyte equals one billion bytes w hen ref erring t o hard drive capacity. Accessible capacity may vary depending on op-
erating environment and formatting.
4.2 Seek performance ch aracteristics
4.2.1 Access time [4]
Not including controller overhead
(witho ut disconnect) [1]
Drive level
Read Write
msec
Average—Typical [2] 8.5 9.5
Single Track—Typical [2] 0.8 1.0
Full Stroke—Typical [2] 16 16.5
4.2.2 Format command execution time (in minutes)
ST3500071FC ST3400071FC
Maximum (wi th verify)
Maximum (without verify)
375 360
170 155
Page 20
12
NL35 Series FC Product Manual, Rev. D
4.2.3 Generalized performance characteristics
Minimum sector interleave 1 to 1
Data buffer transfer rate to/from disc media (one 512-byte sector):
ST3500071FC ST3400071FC
Minimum [3]* 33 35 MBytes/sec
Maximum [3] 66 66 MB ytes/sec
Sustainable disc transfer rate:
ST3500071FC ST3400071FC
Minimum [3]* 32 27 MBytes/sec
Maximum [3] 67 56 MB ytes/sec
Fibre Channel Interface maximum instantaneous transfer rate
1 GHz 2 GHz
106 Mbytes/sec* per port
(dual port = 212 Mbytes/
sec*)
Note. 1 Megabyte (MB) = 1,000,000 bytes.
Sector Sizes
Default is 512-byte data blocks.
Logical block sizes
Default is 512-byte data blocks
512, 520, 524, and 528 supported.
Read/write consecutive sectors on a track Yes
Flaw reallocation performance impact (for flaws reallocated at format time
using the spare sectors per sparing zone reallocation scheme.)
Overhead time for head switch in sequential mode
Overhead time for one track cylinder switch in sequential mode 0.66 msec (typical)
Average rotational latency 4.17 msec
Negligible
1.56 msec
212 Mbytes/sec* per
port (dual port = 424
Mbytes/sec*)
*Assumes no errors and no relocated logical blocks. Rate measured from the start of the first logical block transfer to or
from the host.
Notes for Section 4.2.
[1] Execution time measured from receipt of the last byte of the Command Descriptor Block (CDB) to the
request for a Status Byte Transfer to the Initiator (excluding connect/disconnect).
[2] Typical access times are measured under nominal conditions of temperature, voltage, and horizontal ori-
entation as measured on a representative sampl e of drives.
[3] Assumes system ability to support the rates listed and no cable loss.
[4] Access to data = access tim e + latency time.
Page 21
NL35 Series FC Product Manual, Rev. D
13
4.3 Start/stop time
If the Motor Start option is disabled, the drive becomes ready within 25 seconds after DC power is applied. If a
recoverable error conditio n i s detect ed dur ing the sta rt seq uence, the dr i ve execu tes a re cover y proce dure and
the time to become ready may exceed 25 seconds. Stop time is less than 30 seconds (maximum) from
removal of DC power.
If the Motor Start option is enabled, the internal controller accepts the commands listed in the Fibre Channel
Interface Manual less than 3 seconds after DC power has been applied. After the Motor Start command has
been received, the drive becomes ready for normal operations within 25 seconds (excluding the err or reco very
procedure). The Motor Start command can also be used to command the drive to stop the spindle.
There is no power control switch on the drive.
4.4 Prefetch /m ulti-segmen te d cache contro l
The drive provides a prefetch (read look-ahead) and multi-segmented cache control algorithms that in many
cases can enhance system performance. Cache refers to the drive buffer storage space when it is used in
cache operations. To select this feature, the host sends the Mode Select command with the proper values in
the applicable bytes in page 08h. Prefetch and cache operations are independent features from the standpoint
that each is enabled and disabled independently using the Mode Select command; however, in actual operation, the prefetch feature overlaps cache operation somewhat as described in sections 4.5.1 and 4.5.2.
All default cache and prefetch mode parameter values (Mode Page 08h) for standard OEM versions of this
drive family are given in Table 25.
4.5 Cache operation
Note. Refer to the Fibre Ch anne l Interface Manual for more detail concerning the cache bits.
Of the 8,192 kbytes physical buf fer sp ace i n the drive, 6,9 91 kbytes ca n be used as a ca che. Th e buf fer can be
divided into logical se gmen ts (using Mode Select Page 08h, byte 1 3) fr om whic h dat a is rea d and to which data
is written.
The drive keeps track of the logical block addresses of the data stored in each segment of the buffer. If the
cache is enabled (see RCD bit in the Fibre Channel Interface Manual ), data requested by the host with a read
command is retrieved from the buffer, if possible, before any disc access is initiated. If cache operation is not
enabled, the buffer (still segmented with the required number of segments) is still used, but only as circular
buffer segments during disc medium read operations (disregarding Prefetch operation for the moment). That
is, the drive doe s not ch eck in th e buffer segments fo r the req uested read data, but go es di re ctly to th e medium
to retrieve it. The retrieved data merely passes through some buffer segment on the way to the host. On a
cache miss, all data transfers to the host are in accordance with buffer-full ratio rules. On a cache hit, the drive
ignores the buffer -ful l rat io rul es. See the exp lanati on provide d with the infor mation about Mo de P age 02h (disconnect/reconnect control) in the Fibre Channel Interface Manual.
The following is a simplified description of the prefetch/cache operation:
Case A—read command is received and the first logical block is already in the cache:
1. Drive transfers to the initiator the first logical block requested plus all subsequent cont iguous logi cal blocks
that are already in the cache. This data may be in multiple segments.
2. When a requested logical block is reached that is not in any cache segment, the drive fetches it and any
remaining requested logical block addresses from the disc and puts them in a segment of the cache. The
drive transfers the remaining requested logical blocks from the cache to the host in accordance with the
Mode Select Disconnect/Reconnect parameters, page 02h.
3. If the prefetch feature is enabled, refer to section 4.5.2 for operation from this point.
Page 22
14
NL35 Series FC Product Manual, Rev. D
Case B—A Read command requests data, and the first logical block is not in any segment of the cache:
1. The drive fetches the requested logical blocks from the disc and transfers them into a segment, and then
from there to the host in accordance with the Mode Select Disconnect/Reconnect parameters, page 02h.
2. If the prefetch feature is enabled, refer to section 4.5.2 for operation from this point.
During a prefetch, the drive crosses a cylinder boundary to fetch data only if the Discontinuity (DISC) bit is set
to 1 in bit 4 of byte 2 of the Mode Select parameters page 08h. Default is zero for bit 4.
Each cache segment is actually a self-contained circular buffer whose length is an integer number of logical
blocks. The wrap-around capability of the individual segments greatly enhances the cache’s overall performance, allowing a wide range of user-selectable configurations. The drive supports operation of any integer
number of segments from 1 to 32. Divide the 6,877 Kbytes in the buffer by the number of segments to get the
segment size in bytes; then divi de b y the sector size to get the num ber of sector s per se gmen t, any p ar tial sectors remaining are not used. Default is 3 segments.
Note. The size of each segment is not reported by Mode Sense command page 08h, bytes 14 and 15.
The value 0XFFFF is always reported regardless of the actual size of the segment. Sending a size
specification using the Mode Select command (bytes 14 and 15) does not set up a new segment
size. If the STRICT bit in Mode page 00h (byte 2, bit 1) is set to one, the drive responds as it does
for any attempt to change an unchangeable parameter.
4.5.1 Caching write data
Write caching is a write operation by the drive that makes use of a drive buffer storage area where the data to
be written to the medium is stored while the drive performs the Write command.
If read caching is enabled (RCD=0), then data written to the medium is retained in the cache to be made available for future read cache hits. The same buffer space and segmentation is used as set up for read functions.
The buffer segmentation scheme is set up or changed independently, having nothing to do with the state of
RCD. When a write command is issued, if RCD=0, the cache is first checked to see if any logical blocks that
are to be written are already stored in the cache from a previous read or write command. If there are, the
respective cache segments are cleared. The new data is cached for subsequent Read commands.
If the number of write dat a logical blo cks excee d the size o f the segm ent b eing wr itten into, wh en th e en d of the
segment is reached, the data is written i nto the b eginning of the same cache segment, overwriting the dat a that
was written there at the beginning of the operation; however, the drive does not overwrite data that has not yet
been written to the medium.
If write caching is enabled (WCE=1), then the drive may return Good status on a write command after the data
has been transferred into the cache, but before the data has been written to the medium. If an error occurs
while writing the data to the medium, and Good status has already been returned, a deferred error will be generated.
The Synchronize Ca che command may be used to force the drive to write all cached wri te dat a to the med ium.
Upon completion of a Synchronize Cache command, all data received from previous write commands will have
been written to the medium.
Table 25 shows the mode default settings for the drive.
4.5.2 Prefetch operation
If the Prefetch feature is enabled, data in contiguous logical blocks on the disc immediately beyond that which
was requested by a Read command are retrieved and stored in the buffer for immediate transfer from the
buffer to the host on subsequent Read commands that request those logical blocks (this is true even if cache
operation is disabled). Though the prefetch operation uses the buffer as a cache, finding the requested data in
the buffer is a prefetch hit, not a cache operation hit.
Page 23
NL35 Series FC Product Manual, Rev. D
15
To enable Prefetch, use Mode Select page 08h, byte 12, bit 5 (Disable Read Ahead—DRA bit). DRA bit = 0
enables prefetch.
Since data that is prefetched replaces data already in some buffer segments, the host can limit the amount of
prefetch data to optimize system performance. The Max Prefetch field (bytes 8 and 9) limits the amount of
prefetch. The drive does not use the Prefetch Ceiling field (bytes 10 and 11).
During a prefetch operation, the drive crosses a cylinder boundary to fetch more data only if Mode parameters
page 08h, byte 2, bit 4 is set to 1 (Discontinuity—DISC bit).
When prefetch (read look-ahead) is enabled (enabled by DRA = 0), it operates under the control of ARLA
(Adaptive Read Look-Ahead). If the host uses software interleave, ARLA enables prefetch of contiguous
blocks from the disc when it senses that a prefetch hit will likely occur, even if two consecutive read operations
were not for physically contiguous blocks of data (e.g. “software interleave”). ARLA disables prefetch when it
decides that a prefetch hit will not likely occur. If the host is not using software interleave, and if two sequential
read operations are not for contiguous blocks of data, ARLA disables prefetch, but as long as sequential read
operations request contiguous blocks of data, ARLA keeps prefetch enabled.
4.5.3 Optimizing cache performance for desktop and server applications
Desktop and server applications require different drive caching operations for optimal performance. This
means it is difficult to provide a single configuration that meets both of these needs. In a desktop environment,
you want to configure the cache to respond quickly to repetitive accesses of multiple small segments of data
without taking the time to “look ahead” to the next contiguous segments of data. In a server environment, you
want to configure the cache to provide large volumes of sequential data in a non-repetitive manner. In this
case, the ability of the cache to “look ahead” to the next contiguous segments of sequential data is a good
thing.
The Performance Mode (PM) bit controls the way the drive switches the cache buffer into different modes of
segmentation. In “server mode” (PM bit = 0), the drive can dynamically change the number of cache buffer
segments as needed to optimize the performance, based on the command stream from the host. In “desktop
mode” (PM bit = 1), the number of segments is maintained at the value defined in Mode Page 8, Byte 13, at all
times. For additional information about the PM bit, refer to the Unit Attention Parameters page (00h) of the
Mode Sense command (1Ah) in the Fibre C hanne l Interface Product Manual, part number 77767496.
Page 24
16
NL35 Series FC Product Manual, Rev. D
Page 25
NL35 Series FC Product Manual, Rev. D
17
5.0 Reliability specifications
The following reliability specifications assume correct host and drive operational interface, including all interface timings, power supply voltages, environmental requirements and drive mounting constraints
Seek error rate Less than 1 error in 107 seeks
Read Error Rates
Recovered Data Less than 10 errors in 1012 bits transferred (OEM default settings)
Unrecovered Data Less than 1 sector in 1014 bits transferred
Miscorrected Data Less than 1 sector in 1021 bits transferred
Interface error rate Less than 1 error in 1011 bits transferred with minimum receive eye
MTBF 1,000,000 hours
Service life 5 years.
Warranty To determine the warranty for a specific drive, use a web browser to
Preventive maintenance None required.
1
Less than 1 error in 1014 bits transferred with typical receive eye
(see Section 9.6.4, "Differential PECL input." on page 68)
access the following web page:
www.seagate.com/support/service/
From this page, click on the “Verify You r Warranty” link. You will be
asked to provide the drive serial number, model number (or part number) and country of pur chase. The system will display t he warranty info rmation for your drive.
1. Error rate specified with automatic retries and data correction with ECC enabled and all flaws reallocated.
5.1 Error rates
The error rates stated in this manual assume the following:
• The drive is operated in accordance with this manual using DC power as defined in paragraph 6.2, "DC
power requirements."
• Errors caused by host system failures are excluded from error rate computations.
• Assume random data.
• Default OEM error recovery settings are applied. This includes AWRE, ARRE, full read retries, full write
retries and full retry time.
Page 26
18
NL35 Series FC Product Manual, Rev. D
5.1.1 Recoverable Errors
Recovereable errors are those detected and corrected by the drive, and do not require user intervention.
Recoverable Data errors will use correction, although ECC o n-the-fly is not considered fo r purposes o f recov-
ered error specifications.
Recovered Data error rate is determined using read bits transferred for recoverable errors occurring during a
read, and using write bits transferred for recoverable errors occurring during a write.
5.1.2 Unrecoverable errors
Unrecoverable Data Errors (Sense Key = 03h) are specified at less than 1 sector in error per 1014 bits transferred. Unrecoverable Data Errors resulting from the same cause are treated are 1 error for that block.
5.1.3 Seek errors
A seek error is defined as a failure of the drive to position the heads to the addressed track. After detecting an
initial seek error, the drive automaticall y perf orms an error recovery process. If the error recover y process fails,
a seek positioning error (Error code = 15h or 02h) will be reported with a Hardware error (04h) in the Sense
Key. Recoverable seek errors are specified at Less than 10 errors in 108 seeks. Unrecoverable seek errors
(Sense Key = 04h) are classified as drive failures.
5.1.4 Interface errors
An interface error is defined as a failure of the receiver on a port to recover the data as transmitted by the
device port connected to the receiver. The error may be detected as a running disparity error, illegal code, loss
of word sync, or CRC error. The total error rate for a loop of devices is the sum of the individual device error
rates.
5.2 Reli ab ilit y and servi ce
You can enhance the reliability of NL35 Serie s disc drives by ensur ing that the drive receives adequa te co oling.
Section 6.0 provides temperature measurements and other information that may be used to enhance the service life of the drive. Section 8.2 provides recommended air-flow information.
Page 27
NL35 Series FC Product Manual, Rev. D
19
5.2.1 Mean Time Between Failure (MTBF)
The production disc drive shall achieve an MTBF of 1,000,000 hours when operated in an environment that
ensures the HDA case temperatures specified in Section 6.4 are not exceeded. Short-term excursions up to
the specification limits of the operating environment will not affect MTBF performance. Continual or sustained
operation at case temperatures above the values shown in Section 6.4.1 may degrade product reliability.
Estimated power-on operation hours means power-up hours per disc drive times the total number of disc
drives in service. Each disc drive shall have accumulated at least nine months of operation. Data shall be calculated on a rolling average base for a minimum period of six months.
MTBF is based on the following assumptions:
• 8,760 power-on hours per year.
• 250 average on/off cycles per year.
• Operations at nominal voltages.
• Systems will provide adequate cooling to ensure the case temperatures specified in Section 6.4.1 are not
exceeded.
Drive failure means any stoppage or substandard performance caused by drive malfunction.
A S.M.A.R.T. predictive failure indicates that the drive is deteriorating to an imminent failure and is considered
an MTBF hit.
5.2.2 Preventive mainte nance
No routine scheduled preventive maintenance is required.
5.2.3 Hot plugging the drive
Inserting and removing the drive on the FC-AL will interrupt loop operation. The interruption occurs when the
receiver of the next device in the loop must synchronize to a different input signal. FC error detection mechanisms, character sync, running disp a rity, word sync, and CRC are able to detect any error. Recovery is initiated
based on the type of error.
The disc drive defaults to the FC-AL Monitoring state, Pass-through state, when it is powered-on by switching
the power or hot plugged. The control line to an optional port bypass circuit (external to the drive), defaults to
the Enable Bypass state. If the bypass circuit is present, the next device in the loop will continue to receive the
output of the previous device to the newly inserted device. If the bypass circuit is not present, loop operation is
temporarily disrupted until the next device starts receiving the output from the newly inserted device and
regains synchronization to the new input.
The Pass-through state is disabled while the drive perfo rms self test of the FC interface. The control line for an
external port bypass circuit remains in the Enable Bypass state while self test is running. If the bypass circuit is
present, loop oper ation m ay con tinue. If the byp ass circ uit is not pres ent, loo p ope ration will be h alted while the
self test of the FC interface runs.
When the self test completes successfully, the control line to the bypass circuit is disabled and the drive enters
the FC-AL Initializing st a te. The receiver on the ne xt device i n the loo p must synch ronize t o outpu t of the newly
inserted drive.
If the self-test fails, the control line to the bypass circuit remains in the Enable Bypass state.
Note. It is the responsibility of the systems integrator to assure that no temperature, energy, voltage haz-
ard, or ESD potential hazard is presented during the hot connect/disconnect operation. Discharge
the static electricity from the drive carrier prior to inserting it into the system.
Caution. The drive motor m ust come to a com pl ete s top pr ior to ch angi ng the pla ne of o pera ti on. T his time i s
required to insure data integrity.
Page 28
20
NL35 Series FC Product Manual, Rev. D
5.2.4 S.M.A.R.T.
S.M.A.R.T. is an acronym for Self-Monitoring Analysis and Reporting Technology. This technology is intended
to recognize conditions that indicate imminent drive failure and is designed to provide sufficient warning of a
failure to allow you to back up the data before an actual failure occurs.
Note. The drive’ s f irmwar e moni tor s specific attr ibutes for degr adatio n ove r tim e b ut can ’ t predi ct in sta nt a-
neous drive failures.
Each monitored attribute has been selected to monitor a specific set of failure conditions in the operating performance of the drive and the thresholds are optimized to minimize “false” and “failed” predi ctions.
Controlling S.M.A.R.T.
The operating mode of S.M.A.R. T. is controlled by the DEXCPT and PERF bits on the Informational Exce ptions
Control mode page (1Ch). Use the DEXCPT bit to enable or disable the S.M.A.R.T. feature. Setting the DEXCPT bit disables all S.M.A.R.T. functions. When enab led, S .M. A.R.T. collects on -line d ata as the drive p erfor ms
normal read and write operations. When the PERF bit is set, the drive is considered to be in “On-line Mode
Only” and will not perform off-line functions.
You can measure off-line attributes and force the drive to save the data by using the Rezero Unit command.
Forcing S.M.A.R.T. resets the timer so that the next scheduled interrupt is in two hours.
You can interrogate the drive through th e host t o dete rmine the time remaining b efore the ne xt schedu l ed me asurement and d at a logg i ng p rocess occur s . To accomplish this, i ssue a Log Sense command to log page 0x3E.
This allows you to control when S.M.A.R.T. interruptions occur. Forcing S.M.A.R.T. with the RTZ command
resets the timer.
Performance impact
S.M.A.R.T. attribute data is saved to the disc so that the events that caused a predictive failure can be recreated. The drive measures and saves parameters once every two hours subject to an idle period on the FC-AL
bus. The process of measuring off-line attribute data and saving data to the disc is uninterruptable. The maximum on-line only processing delay is summarized below:
Maximum processing delay
S.M.A.R.T. delay times
On-line only delay
DEXCPT = 0, PERF = 1
60 milliseconds
Fully-enabled delay
DEXCP T = 0, PE R F = 0
370 milliseconds
Reporting control
Reporting is controlled by the MRIE bits in the Informational Exceptions Control mode page (1Ch). Subject to
the reporting method, the firmware will issue to the host an 01-5Dxx sense code. The error code is preserved
through bus resets and power cycles.
Determining rate
S.M.A.R.T. monitors the rate at which errors occur and si gna ls a predi ctive fai lure if the rat e of degrad ed err ors
increases to an unacceptabl e level. To determine rate, error events are logged and com pa red to the num ber of
total operations for a given attribute. The interval defines the number of operations over which to measure the
rate. The counter that keeps track of the current number of operations is referred to as the Interval Counter.
S.M.A.R.T. measures error rates. All errors for each monitored attribute are recorded. A counter keeps track of
the number of errors for the current interval. This counter is referred to as the Failure Counter.
Page 29
NL35 Series FC Product Manual, Rev. D
21
Error rate is the number of errors per oper ation. The algori thm tha t S .M.A.R .T. uses to record rate s of err or i s to
set thresholds for the number of errors and their interval. If the number of errors exceeds the threshold before
the interval expires, the error rate is considered to be unacceptable. If the number of errors does not exceed
the threshold before the interval expires, the error rate is considered to be acceptable. In either case, the interval and failure counters are reset and the process starts over.
Predictive failures
S.M.A.R.T. signals predictive failures when the drive is performing unacceptably for a period of time. The firmware keeps a running count of the number of times the error rate for each attribute is unacceptable. To accomplish this, a counter is incremented each time the error rate is unacceptable and decremented (not to exceed
zero) whenever the error rate is acceptable. If the counter continually increments such that it reaches the predictive threshold, a predictive failure is signaled. This counter is referred to as the Failure History Counter.
There is a separate Failure History Counter for each attribute.
5.2.5 Thermal monitor
NL35 Series drives implement a temperature warning system which:
1. Signals the host if the temperature exceeds a value which would threaten the drive.
2. Signals the host if the temperature exceeds a user-specified value.
3. Saves a S.M.A.R.T. data frame on the drive which exceed the threatening temperature value.
A temperature sensor monitors the drive temperature and issues a warning over the interface when the tem-
perature exceeds a set threshold. The temperature is measured at power-up and then at ten-minute intervals
after power-up.
The thermal monitor system generates a warning code of 01-0B01 when the temperature exceeds the specified limit in compliance with the SCSI standard. The drive temperature is reported in the FRU code field of
mode sense dat a. You can use this infor matio n to deter mine if the warning i s due to t he tem per atur e excee ding
the drive threatening temperature or the user-specified temperature.
This feature is controlled by the En able W a rni ng (EWasc) bit, and the reporting mechanism is controlled by the
Method of Reporting Informational Exceptions field (MRIE) on the Informational Exceptions Control (IEC)
mode page (1Ch).
The current algorithm implements two temperature trip points. The first trip point is set at 68°C which is the
maximum temperature limit according to the drive specification. The second trip point is user-selectable using
the Log Select command. The re feren ce tempe ratur e p aram eter in the tempera ture log page (see Table 1) can
be used to set this trip point. The default value for this drive is 68°C, however, you can set it to any value in the
range of 0 to 68°C. If you specify a temperature greater than 68°C in this field, the temperature is rounded
down to 68°C. A sense code is sent to the host to indicate the rounding of the parameter field.
T ab le 1: Temperature Log page (0Dh)
Parameter Code Description
0000h Primary Temperature
0001h Reference Temperature
When the first tem perature trip point is exceeded , S. M.A .R.T. data is collected and a fram e is save d to th e disc.
Page 30
22
NL35 Series FC Product Manual, Rev. D
5.2.6 Drive Self Test (DST)
Drive Self Test (DST) is a technology designed to recognize drive fault conditions that qualify the drive as a
failed unit. DST validates the functionality of the drive at a system level.
There are two test coverage options implemented in DST:
1. Extended test
2. Short text
The most thorough option is the extended test that performs various tests on the drive and scans every logical
block address (LBA) of the drive. The short test is time-restricted and limited in length—it does not scan the
entire media surface, but does some fundamental tests and scans portions of the media.
If DST encounters an error during either of these tests, it reports a fault condition. If the drive fails the test,
remove it from service and return it to Seagate for service.
5.2.6.1 DST Failure Definition
The drive will present a “diagnostic failed” condition through the self-tests results value of the diagnostic log
page if a functional failure is encountered during DST. The channel and servo parameters are not modified to
test the drive more stringently, and the number of retries are not reduced. All retries and recovery processes
are enabled during the test. If data is recoverable, no fa ilure condition will be reported regardless of the number
of retries required to recover the data.
The following conditions are considered DST failure conditions:
• Seek error after retries are exhausted
• Track-follow error after retries are exhausted
• Read error after retries are exhausted
• Write error after retries are exhausted
Recovered errors will not be reported as diagnostic failures.
5.2.6.2 Implementation
This section provides all of the information necessary to implement the DST function on this drive.
5.2.6.2.1 State of the drive prior to testing
The drive must be in a ready state before issuing the Send Diagnostic command. There are multiple reasons
why a drive may not be ready, some of which are valid conditio ns, and not erro rs. For example, a drive may be
in process of doing a form at, or anothe r D ST. It is the responsibility o f the ho st applic atio n to det erm ine the “ not
ready” cause.
While not technically part of DST, a Not Ready condition also qualifies the drive to be returned to Seagate as a
failed drive.
A Drive Not Ready condition is reported by the drive under the following conditions:
• Motor will not spin
• Motor will not lock to speed
• Servo will not lock on track
• Drive cannot read configuration tables from the disc
In these conditions, the drive responds to a Test Unit Ready command with an 02/04/00 or 02/04/03 code.
Page 31
NL35 Series FC Product Manual, Rev. D
23
5.2.6.2.2 Invoking DST
To invoke DST, submit the Send Diagnostic command with the appropriate Function Code (001b for the short
test or 010b for the extended test) in bytes 1, bits 5, 6, and 7. Refer to the Fibre Channel Interface Product
Manual, part number 77767496, for additional information about invoking DST.
5.2.6.2.3 Short and extended tests
DST has two testing options:
1. short
2. extended
These testing options are described in the following two subsections.
Each test consists of three segments: an electrical test segment, a servo test segment, and a read/verify scan
segment.
Short test (Function Code: 001b)
The purpose of the short test is to provide a time-limited test that tests as much of the drive as possible within
120 seconds. The short test does not scan the entire media surface, but does some fundamental tests and
scans portions of the media. A complete rea d/ver ify scan is not per formed and onl y factua l failu res will report a
fault condition. This option provides a quick confidence test of the drive.
Extended test (Function Code: 010b)
The objective of the extended test option is to empirically test critical drive components. For example, the seek
tests and on-track operations test the positioning mechanism. The read operation tests the read head element
and the media surface. The write element is tested through read/write/read operations. The integrity of the
media is checked through a read/verify scan of the media. Motor functionality is tested by default as a part of
these tests.
The anticipated length of the Extended test is reported through the Control Mode page.
5.2.6.2.4 Log page entries
When the drive begins DST, it creates a new entry in the Self-test Results Log page. The new entry is created
by inserting a new self-te st parameter block a t the beginning of t he se lf-test results log p a ram eter section of the
log page. Existing data will be moved to make room for the new parameter block. The drive reports 20 parameter blocks in the log p ag e. If th ere are more than 20 p ar amet er blocks, the least r ecent p a rame ter block will be
deleted. The new parameter block will be initialized as follows:
1. The Function Code field is set to the same value as sent in the DST command
2. The Self-Test Results Value field is set to Fh
3. The drive will store the log page to non-volatile memory
After a self-test is complete or has been aborted, the drive updates the Self-Test Results Value field in its Self-
Test Results Log page in non-volatile memory. The host may use Log Sense to read the results from up to the
last 20 self-tests performed by the drive. The self-test results value is a 4-bit field that reports the results of the
test. If the field is zero, the drive passed with no errors detected by the DST. If the field is not zero, the test
failed for the reason reported in the field.
The drive will report the failure condition and LBA (if applicable) in the Self-test Results Log parameter. The
Sense key, ASC, ASCQ, and FRU are used to report the failure condition.
Page 32
24
NL35 Series FC Product Manual, Rev. D
5.2.6.2.5 Abort
There are several ways to abort a diagnostic. You can use a SCSI Bus Reset or a Bus Device Reset message
to abort the diagnostic.
You can abort a DST executing in background mode by using the abort code in the DST Function Code field.
This will cause a 01 (self-test aborted by the application client) code to appear in the self-test results values
log. All other abort mechanisms will be reported as a 02 (self-test routine was interrupted by a reset condition).
5.2.7 Product warranty
Beginning on the date of shipment to the customer and continuing for a period of three years, Seagate warrants that each product (including components and subassemblies) that fails to function properly under normal
use due to defect in materials or workmanship or due to nonconformance to the applicable specifications will
be repaired or replaced, at Seagate’s option and at no charge to the customer, if returned by customer at customer’s expense to Seagate’s designated facility in accordance with Seagate’s warranty procedure. Seagate
will pay for transporting the repair or replacement item to the custom er. For more detailed warranty information,
refer to the standard terms and conditions of purchase for Seagate products. Refer to Section 10 for contact
information.
Shipping
When transporting or shipping a drive, use only a Seagate-approved container. Keep your original box.
Seagate approved containers are easily identified by the Seagate Approved Package label. Shippi ng a drive in
a non-approved container voids the drive warranty.
Seagate repair centers may refuse receipt of components improperly packaged or obviously damaged in transit. Contact your authorized Seagate distributor to purchase additional boxes. Seagate recommends shipping
by an air-ride carrier experienced in handling computer equipment.
Product repair and return information
Seagate customer service centers are the only facilities authorized to service Seagate drives. Seagate does
not sanction any third-party repair facilities. Any unauthorized repair or tampering with the factory seal voids
the warranty.
Page 33
NL35 Series FC Product Manual, Rev. D
25
6.0 Physical/electrical specifications
This section provides information relating to the physical and electrical characteristics of the drive.
6.1 AC power re quirements
None.
6.2 DC power re quirements
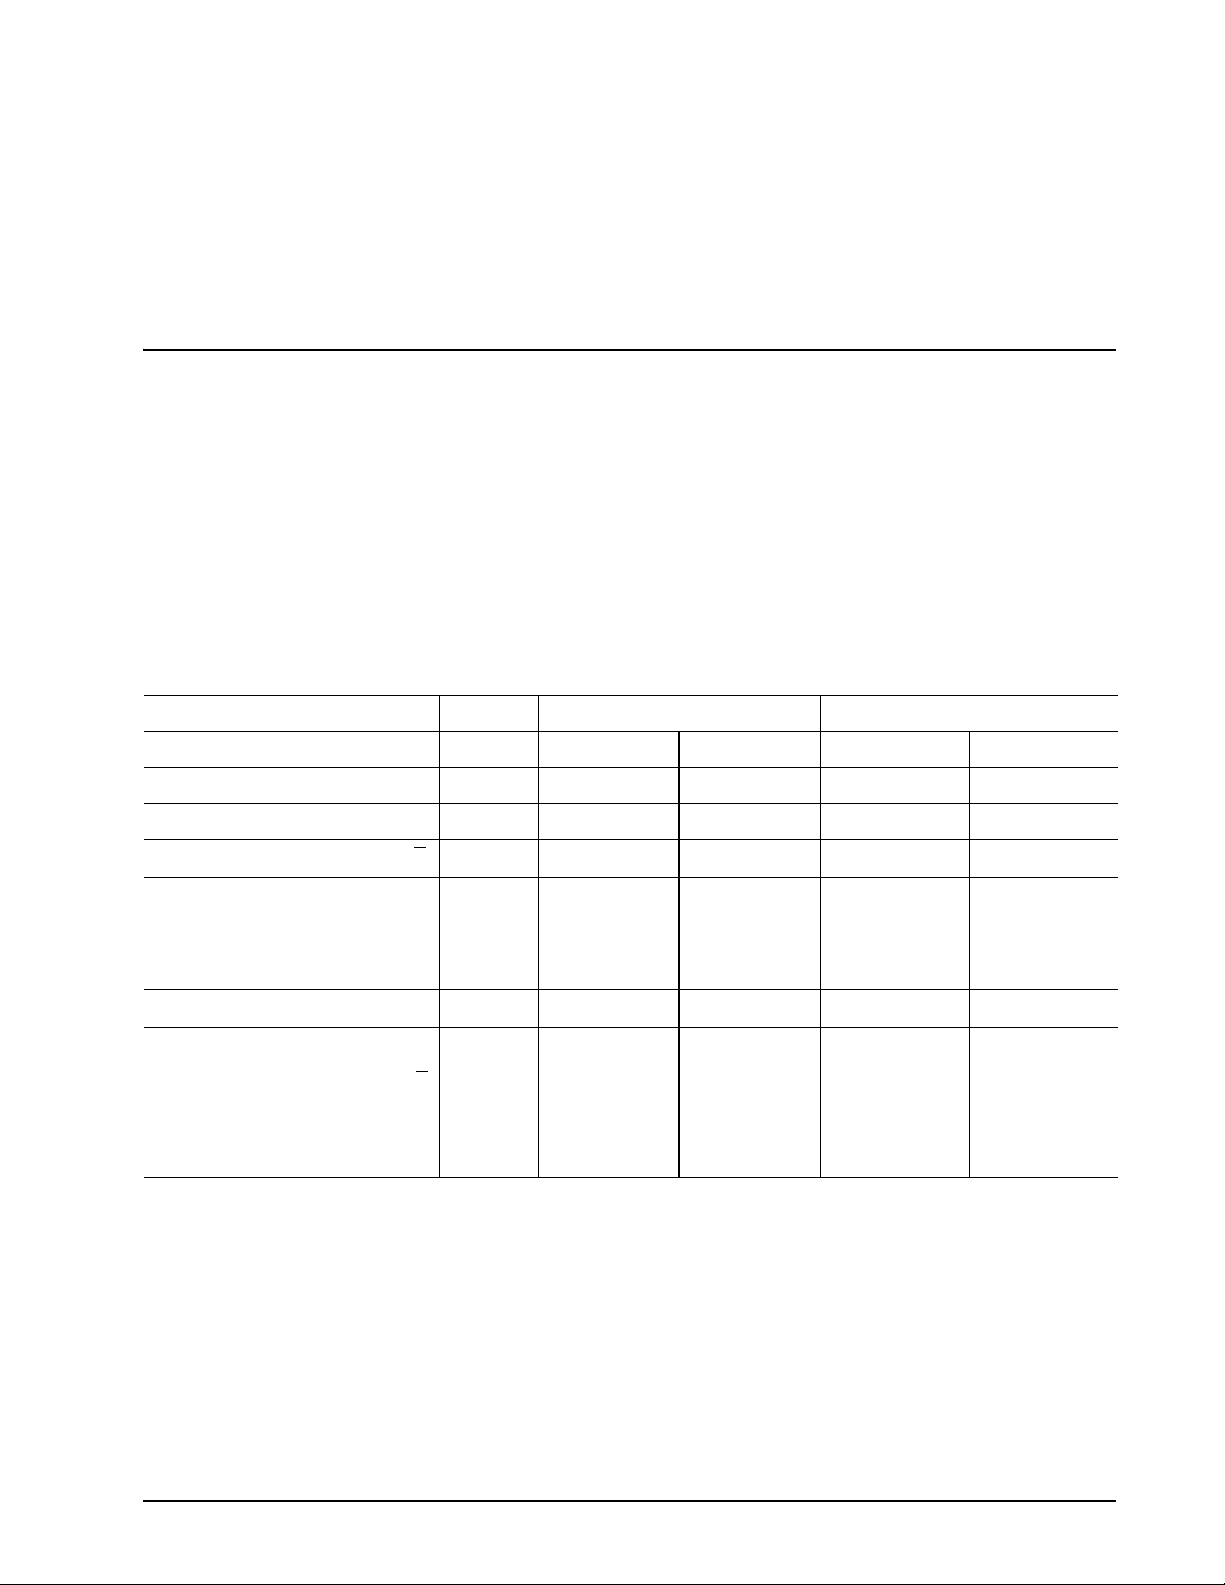
The voltage and current requirements for a single drive are shown below. Values indicated apply at the drive
connector.
T a ble 11: S T3500071FC/ST3400071FC DC power requirements
1 Gbit 2 Gbit
Notes (Amps) (Amps) (Amps) (Amps)
Voltage +5V +12V [2] +5V +12V [2]
Regulation [5] ±5% ±5% [2] ± 5% ±5% [2]
Avg idle current DC X [1] [7]
Maximum starting current
(peak DC) DC 3σ [3]
(peak AC) AC 3σ [3]
Delayed motor start (max) DC 3σ [1] [4]
Peak operating current:
Typical DC X [1] [6]
Maximum DC 3σ [1]
Maximum (peak) DC 3σ
0.94 0.48 1.00 0.48
1.04 2.08 1.10 2.10
1.50 3.54 1.56 3.50
0.57 0.03 0.59 0.03
0.99 0.75 1.05 0.74
1.01 0.77 1.07 0.76
1.68 1.90 1.76 1.90
[1] Measured with average reading DC ammeter. Instantaneous +12V current peaks will exceed these val-
ues. Power supply at nominal voltage. Number of drives tested = 6, 35 Degrees C ambient.
[2] For +12 V, a –10% tolerance is allowed during initial spindle start but must return to ±5% before reaching
7,200 RPM. The ±5% must be maintained after the drive signifies that its power-up sequence has been
completed and that the drive is able to accept selection by the host initiator.
[3] See +12V current profile.
[4] This condition occurs when the Motor Start option is enabled and the drive has not yet received a Start
Motor command.
Page 34
26
NL35 Series FC Product Manual, Rev. D
[5] See paragraph 6.2.1, "Conducted noise immunity." Specified voltage tolerance includes ripple, noise, and
transient response.
[6] Operating condition is defined as random 8 block reads at 161 I/Os per second.
Current and power specified at nominal voltages. Decreasing +5 volt supply by 5% increases 5 volt current by <0.5%. Decreasing +12 volt supply by 5% increases 12 volt current by 1.4%.
[7] During idle, the drive heads are relocated every 60 seconds to a random location within the band from
track zero to one-fourth of maximum track.
General DC power requirement notes.
1. Minimum current loading for each supply voltage is not less than 1.2% of the maximum operating current
shown.
2. The +5V and +12V supplies should employ separate ground returns.
3. Where power is provided to multiple drives from a common supply, careful consideration for individual
drive power requirements should be noted. Where multiple units are powered on simultaneously, the peak
starting current must be available to each device.
4. Parameters, other than spindle start, are measured after a 10-minute warm up.
5. No terminator power.
6.2.1 Conducted noise immunity
Noise is specified as a periodic and random distribution of frequencies covering a band from DC to 20 MHz.
Maximum allowed no ise val ue s given bel ow are pea k to peak mea s urem ent s a nd a pply a t the dr ive po wer co nnector.
+5 V = 250 mV pp from 10 Hz to 10 MHz.
250 mV pp from 10 MHz to 20 MHz.
+12 V = 400 mV pp from 10 Hz to 100 Hz.
800 mV pp from 100 Hz to 8 KHz.
450 mV pp from 8 KHz to 20 KHz.
400 mV pp from 20 KHz to 10 MHz.
250 mV pp from 10 KHz to 20 MHz.
6.2.2 Power sequencing
The drive does not require power sequencing. The drive protects against inadvertent writing during power-up
and down.
Page 35
NL35 Series FC Product Manual, Rev. D
27
6.3 Power dissipation
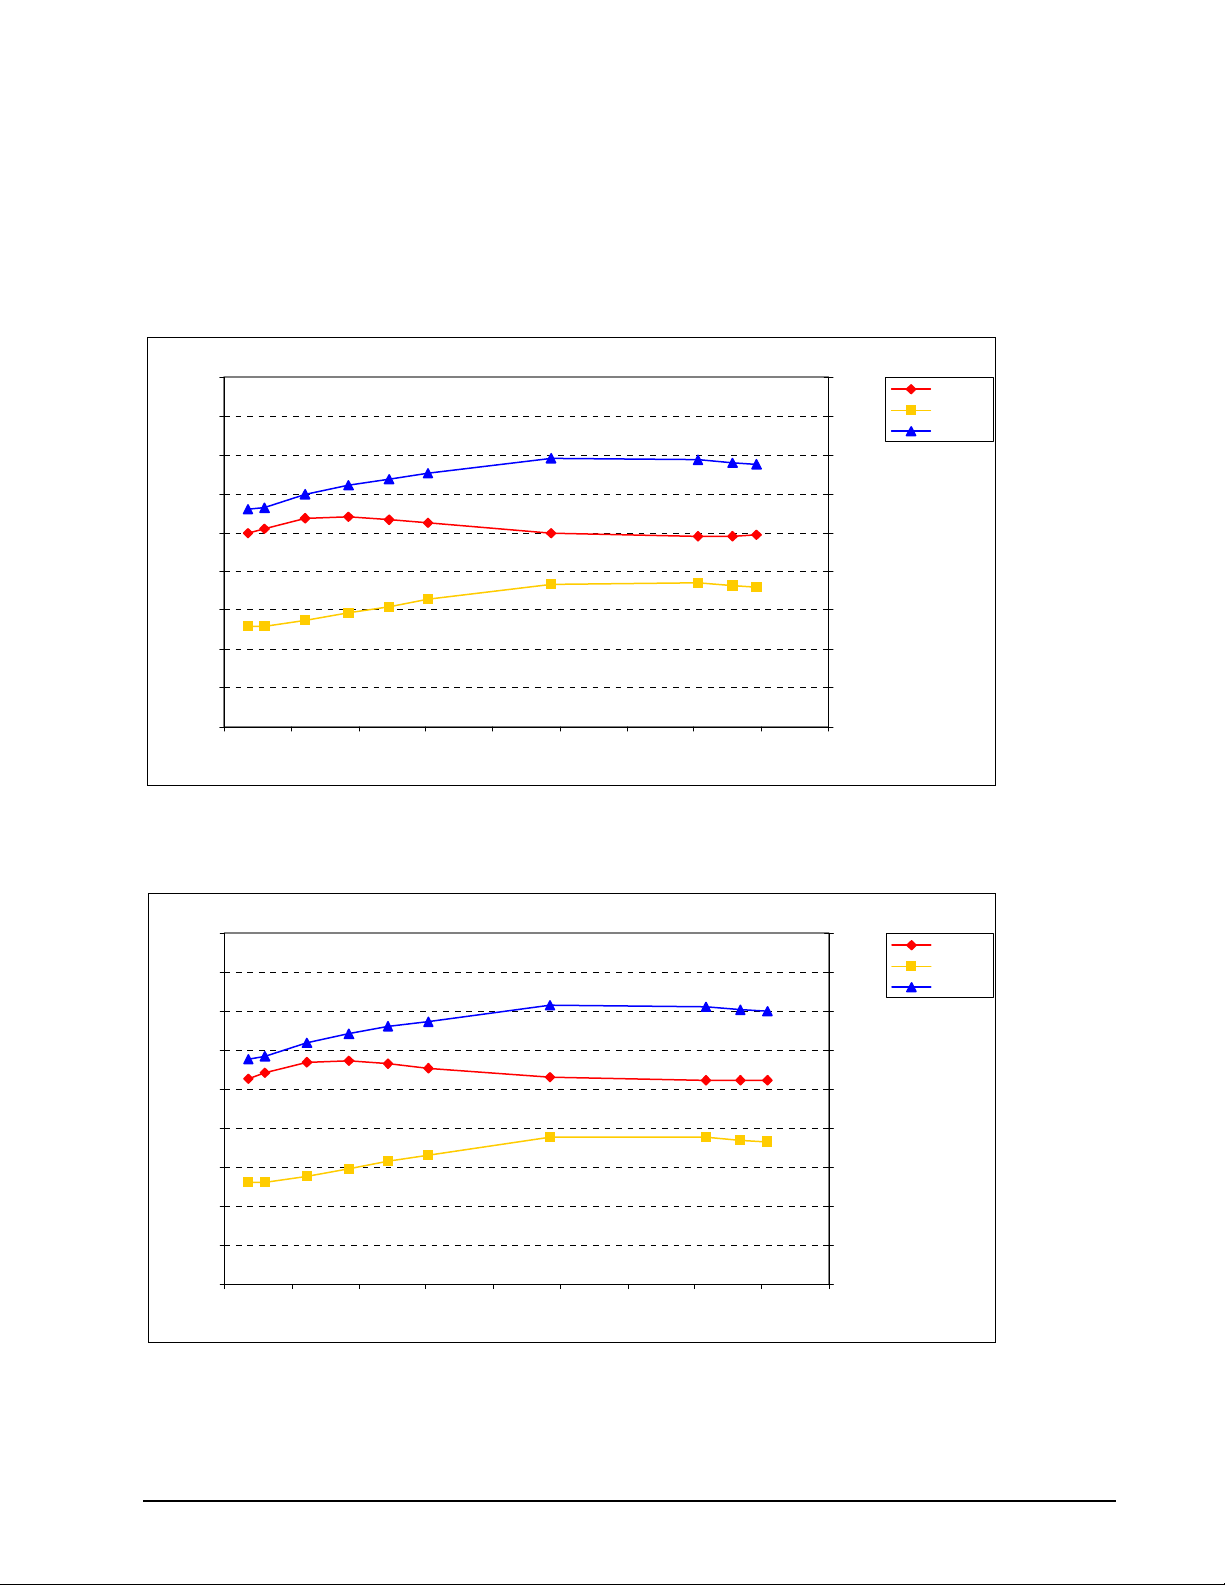
Typical power dissipation under idle conditions is 10.49 watts (35.79 BTUs per hour) during 1 Gbit operation.
Typical power dissipation under idle conditions is 10.75 watts (36.68 BTUs per hour) during 2 Gbit operation.
To obtain operating power for typical random read operations, refer to the following I/O rate curve (see Figure
2). Locate the typical I/O rate for a drive in your system on the horizontal axis and read the corresponding +5
volt current, +12 volt current, and total watts on the vertical axis. To calculate BTUs per hour, multiply watts by
3.4123.
ST3500001FC DC CURRENT/POWER vs THROUGHPUT (1Gb) Random 8 Blo ck Re ads
1.8 0 0
1.6 0 0
1.4 0 0
18.0 0
16.0 0
14.0 0
5Volt A
12 V o l t A
Watts
1.2 0 0
1.0 0 0
0.800
Amperes
0.600
0.400
0.200
0.000
0.0 20.0 40.0 60.0 80.0 100.0 120.0 140.0 160.0 180.0
I/Os per Se cond
Figure 2. DC current and power vs. input/output operations per second (1 Gbit)
ST3500001FC DC CURRENT/POWER vs THROUGHPUT (2Gb) Random 8 Blo ck Re ads
1.8 0 0
1.6 0 0
1.4 0 0
1.2 0 0
12.0 0
10.0 0
8.00
6.00
4.00
2.00
0.00
18.0 0
16.0 0
14.0 0
12.0 0
Power (watts)
5Volt A
12 V o l t A
Watts
Power (watts)
1.0 0 0
0.800
Amperes
0.600
0.400
0.200
0.000
0.0 20.0 40.0 60.0 80.0 100.0 120.0 140.0 160.0 180.0
Figure 3. DC current and power vs. input/output operations per second (2 Gbit)
10.0 0
8.00
6.00
4.00
2.00
0.00
I/Os per Se cond
Page 36
28
NL35 Series FC Product Manual, Rev. D
6.4 Environmental limits
Temperature and humidity values experienced by the drive must be such that condensation does not occur on
any drive part. Altitude and atmospheric pressure specifications are referenced to a standard day at 58.7°F
(14.8°C). Maximum wet bulb temperature is 82°F (28°C).
6.4.1 Temperature
a. Operating
The maximum allowable continuous or sustained HDA case temperature for the rated MTBF is 122°F
(50°C) The maximum allowable HDA case temperature is 60°C. Occasional excursions of HDA case temperatures above 122°F (50°C) or below 41°F (5°C) may occur without impact to specified MTBF. Continual
or sustained operation at HDA case temperatures outside these limits may degrade MTBF.
Provided the HDA case temperatures limits are met, the drive meets all specifications over a 41°F to 131°F
(5°C to 55°C) drive ambient temperature range with a maximum temperature gradient of 36°F (20°C) per
hour . Air flow may be needed in the drive enclosu re to keep within this range (see Se ction 8.3). Operation at
HDA case temperatur es out side thi s ra nge m ay adve rsely af fe ct the d rives ab ility t o mee t speci ficatio ns. To
confirm that the required cooling for the electronics and HDA case is provided, place the drive in its final
mechanical configuration, perform random write/read operations and measure the HDA case temperature
after it has stabilized.
b. Non-operating
–40° to 158°F (–40° to 70°C) package ambient with a maximum gradient of 36°F (20°C) per hour. This
specification assum es th at th e dr iv e is p ackaged in the shipping cont ain er desi gne d by Seagate for use w ith
drive.
HDA Temperature
Check Point
Figure 4. Location of the HDA Temperature check point
0.5”
6.4.2 Relative humidity
The values below assume that no condensation on the drive occurs.
a. Operating
5% to 95% non-condensing relative humidity with a maximum gradient of 20% per hour non-condensing.
b. Non-operating
5% to 95% non-condensing relative humidity with a maximum gradient of 20% per hour non-condensing.
6.4.3 Effective altitude (sea level)
a. Operating
–200 to +10,000 feet (–61 to +3,048 meters)
b. Non-operating
–200 to +40,000 feet (–61 to +12,210 meters)
Page 37
NL35 Series FC Product Manual, Rev. D
29
6.4.4 Shock and vibration
Shock and vibration limits specified in this document are measured directly on the drive chassis. If the drive is
installed in an enclosure to which the stated shock and/or vibration criteria is applied, resonances may occur
internally to t he e nclosure resulting in drive m oveme nt i n excess of t he st at ed l im its. If t hi s situat i on is app ar ent,
it may be necessary to modify the enclosure to minimize drive movement.
The limits of shock and vibration defined within this document are specified with the drive mounted by any of
the four methods shown in Figure 5, and in accordance with the restrictions of Section 8.4.
6.4.4.1 Shock
a. Operating—normal
The drive, as in sta lled for normal op erat ion, s hal l op erat e er ror fr ee wh ile sub je cted to in term i ttent shock not
exceeding 15 Gs at a maximum duration of 11 msec (half sinewave). The drive, as installed for normal
operation, shall operate error free while subjected to intermittent shock not exceeding 25 Gs at a maximum
duration of 2 msec (half sinewave). Shock may be applied in the X, Y, or Z axis.
b. Operating—abnormal
Equipment, as installed for normal operation, does not incur physical damage while subjected to intermittent shock not exceeding 40 Gs at a maximum duration of 11 msec (half sinewave). Shock occurring at
abnormal levels may promote degraded operational performance during the abnormal shock period. Specified operational performance will continue when normal operating shock levels resume. Shock may be
applied in the X, Y, or Z axis. Shock is not to be repeated more than two times per second.
c. Non-operating
The limits of non-operating shock shall apply to all conditions of handling and transportation. This includes
both isolated drives and integrated drives.
The drive subjected to nonrepetitive shock not exceeding 75 Gs at a maximum duration of 11 msec (half
sinewave) shall not exhibit device damage or performance degradation. Shock may be applied in the X, Y,
or Z axis.
The drive subjected to nonrepetitive shock not exceeding 225 Gs at a maximum duration of 2 msec (half
sinewave) does not exhibit device damage or performance degradation. Shock may be applied in the X, Y,
or Z axis.
The drive subjected to nonrepetitive shock not exceeding 120 Gs at a maximum duration of 0.5 msec (half
sinewave) does not exhibit device damage or performance degradation. Shock may be applied in the X, Y,
or Z axis.
d. Packaged
Disc drives shipped as loose load (not palletized) general freight will be packaged to withstand drops from
heights as defined in the table below. For additional details refer to Seagate specifications 30190-001
(under 100 lbs/45 kg) or 30191-001 (over 100 lbs/45 Kg).
Package size Packaged/product weight Drop height
<600 cu in (<9,800 cu cm) Any 60 in (1524 mm)
600-1800 cu in (9,800-19,700 cu cm) 0-20 lb (0 to 9.1 kg) 48 in (1219 mm)
>1800 cu in (>19,700 cu cm) 0-20 lb (0 to 9.1 kg) 42 in (1067 mm)
>600 cu in (>9,800 cu cm) 20-40 lb (9.1 to 18.1 kg) 36 in (914 mm)
Drives packaged in single or multipacks with a gross weight of 20 pounds (8.95 kg) or less by Seagate for
general freight shipment shall withstand a drop test from 48 inches (1,070 mm) against a concrete floor or
equivalent.
Page 38
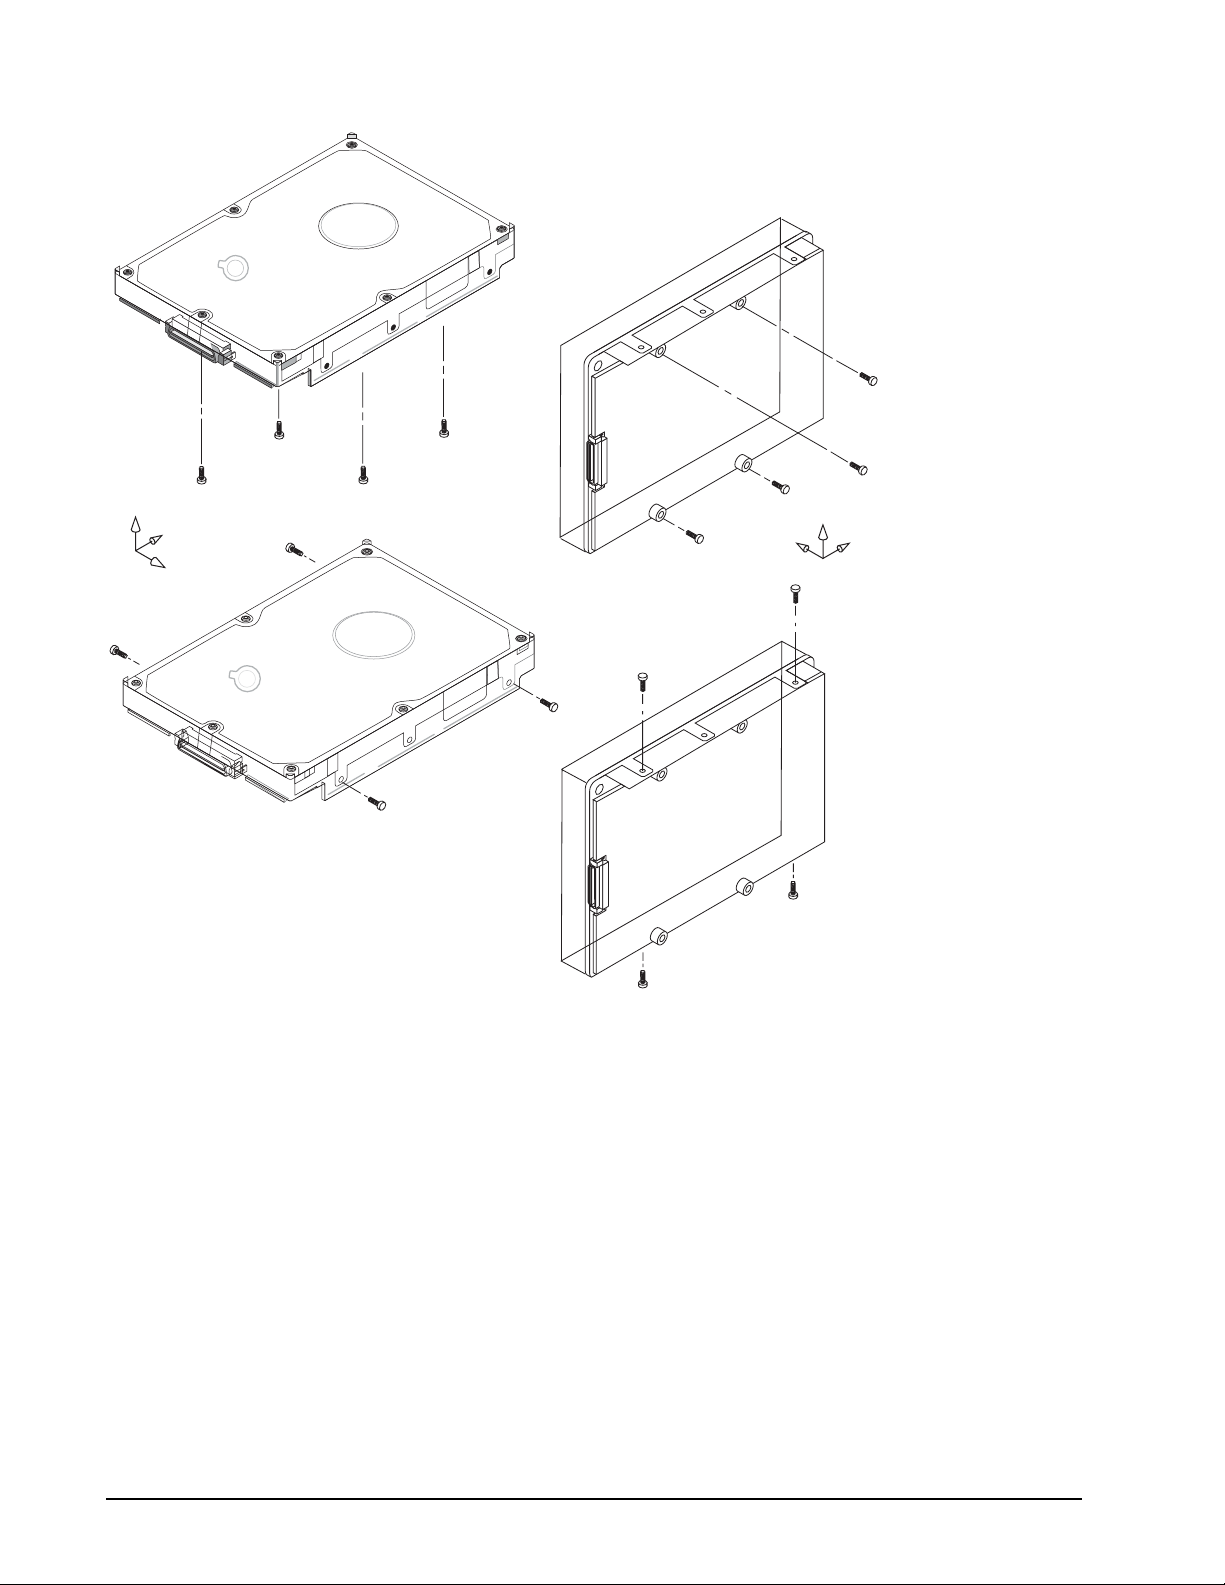
30
NL35 Series FC Product Manual, Rev. D
Z
Y
X
Figure 5. Recommend e d m ounting
X
Z
Y
Page 39
NL35 Series FC Product Manual, Rev. D
31
6.4.4.2 Vibration
a. Operating - normal
The drive as installed for normal operation, shall comply with the complete specified performance while
subjected to continuous vibration not exceeding
5-22 Hz @ 0.25 G (zero to peak)
22-350 Hz @ 0.50 G (zero to peak)
350-500 Hz @ 0.25 G (zero to peak)
Vibration may be applied in the X, Y, or Z axis.
Operating normal translational random flat profile
10 - 500 Hz 0.5 G RMS (grams root mean square)
b. Operating - abnormal
Equipment as installed for normal operation shall not incur physical damage while subjected to periodic
vibration not exceeding:
15 minutes of duration at major resonant frequency
0-22 Hz @ 0.25 G (X, Y, or Z axis, zero to peak)
22-350 Hz @ 0.50 G (X, Y, or Z axis, zero to peak)
350-500 Hz @ 0.25 G (X, Y, or Z axis, zero to peak)
Vibration occurring at these levels may degrade operational performance during the abnormal vibration
period. Specified operational performance will continue when normal operating vibration levels are
resumed. This assumes system recovery routines are available.
Operating abnormal translational random flat profile
10 - 500 Hz 1.2 G RMS (grams root mean square)
c. Non-operating
The limits of non-operating vibration shall apply to all conditions of handling and transportation. This
includes both isolated drives and integrated drives.
The drive shall not incur physical damage or degraded performance as a result of continuous vibration not
exceeding
5-22 Hz @ 0.25 G (zero to peak)
22-350 Hz @ 5.00 G (zero to peak)
350-500 Hz @ 1.0 G (zero to peak)
Vibration may be applied in the X, Y, or Z axis.
Non-operating translational random flat profile
10 - 500 Hz 1.2 G RMS (grams root mean square)
6.4.5 Air cleanliness
The drive is designed to operate in a typical office environment with minimal environmental control.
Page 40
32
NL35 Series FC Product Manual, Rev. D
6.4.6 Corrosive environment
Seagate electronic drive components pass accelerated corrosion testing equivalent to 10 years exposure to
light industrial environments containing sulfurous gases, chlorine and nitric oxide, classes G and H per ASTM
B845. However, this accelerated testing cannot duplicate every potential application environment.
Users should use caution exposing any electronic components to uncontrolled chemical pollutants and corrosive chemicals as electr onic dr i ve com ponen t reliab ilit y can be af fecte d by th e i nst allation environment. Th e si l-
ver, copper, nickel and gold films used in Seagate products are especially sensitive to the presence of sulfide,
chloride, and nitr ate c ont ami na nt s. S ulfur is found to be the m ost dam aging . In ad di tion, e lectron i c comp onent s
should never be exposed to condensing water on the surface of the printed circuit board assembly (PCBA) or
exposed to an am bient rel at ive hum idity gr eate r th an 9 5%. Mat erial s used in cabin et fa bri cation , such as vulcanized rubber, that can outgas corrosive compounds should be minimized or eliminated. The useful life of any
electronic equipment may be extended by replacing materials near circuitry with sulfide-free alternatives.
6.4.7 Acoustics
The typical sound power duri ng idle mod e as measured to IS O 7779 specifi ca tion are l isted in the t abl e below.
T ab le 2: Typical idle mode sound power
ST3500071FC and ST3400071FC
3.1 bels
There will not be any discrete tones more than 10 dB above the masking noise on typical drives when measured according to Seagate specification 30553-001. There will not be any tones more than 24 dB above the
masking noise on any drive.
6.4.8 Electromagn etic susc ept ibili ty
See Section 2.1.2.
Page 41
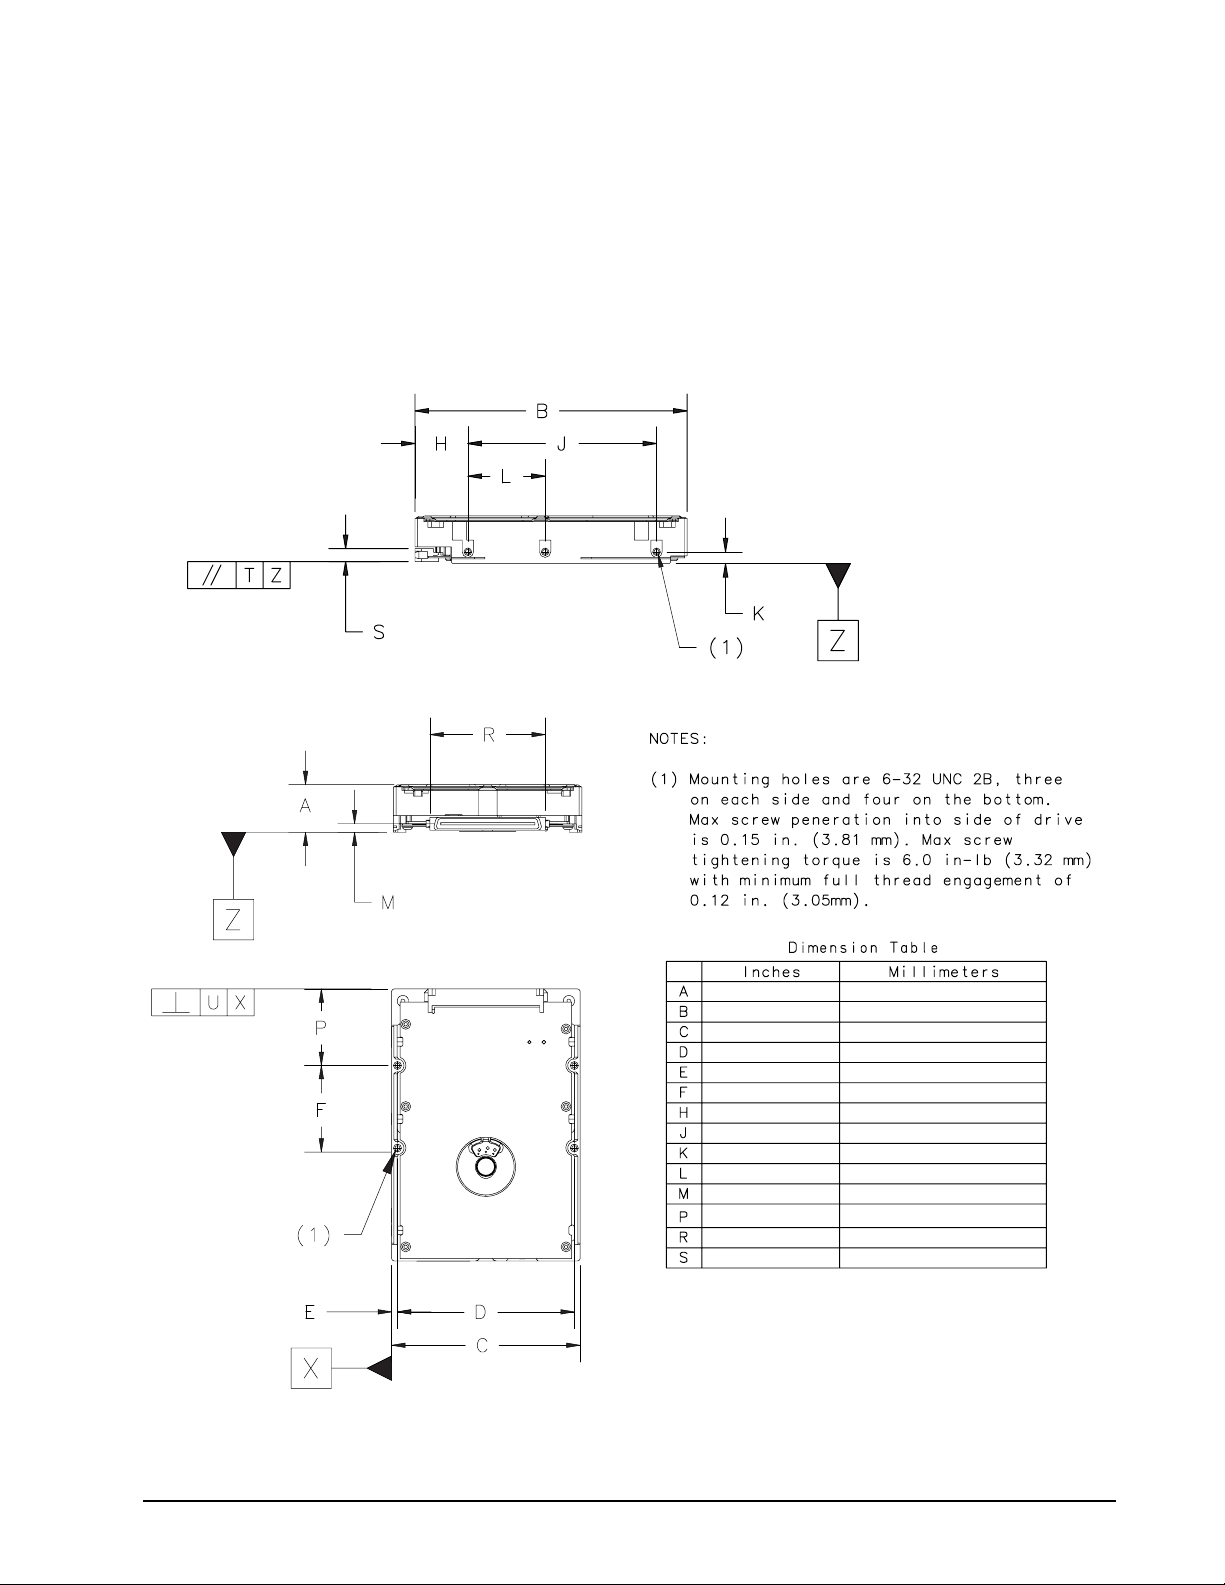
NL35 Series FC Product Manual, Rev. D
33
6.5 Mechanical specifications
The following nominal dimensions are exclusive of the decorative front panel accessory. However, dimensions
of the front panel are shown in figure below. Refer to Figure 6 for detailed mounting configuration dimensions.
See Section 8.4, “Drive mounting.”
Height: 1.010 +/- 0.14 in. 25.654 +/- .356 mm
Width: 4.0 +/- .008 in. 101.6 +/- .203 mm
Depth: 5.770 in. +/- 0.008 in. 146.558 mm +/- 0.203 mm
Weight: 1.6 pounds 0.726 kilograms
Figure 6. Mounting configuration dimensions
1.010 +/- .014 25.654 +/- .356
5.770 +/- .008 146.558 +/- .203
4.000 +/- .008 101.6 +/- .203
3.750 +/- .010 95.25 +/- .254
.125 +/- .010 3.175 +/- .254
1.750 +/- .010 44.45 +/- .254
1.122 +/- .010 28.4988 +/- .254
4.000 +/- .010 101.6 +/- .254
.250 +/- .008 6.35 +/- .254
1.638 +/- .010 41.605 +/- .254
.180 +/- 0.021 4.572 +/- 0.533
1.625 +/- 0.010 41.275 +/- .254
1.469 +/- 0.020 37.31 +/- 0.50
.276 +/- 0.040 7.0104 +/- 1.0160
Page 42
34
NL35 Series FC Product Manual, Rev. D
Page 43
NL35 Series FC Product Manual, Rev. D
35
7.0 Defect and error management
The drive, as delivered, complies with this product manual. The read error rates and specified storage capacities are not dependent upon use of defect management routines by the host (initiator).
Defect and error management in the SCSI protocol involves the drive internal defect/error management and
FC-AL system error considerations (errors in communications between the initiator and the drive). Tools for
use in designing a defect/error management plan are briefly outlined in this section. References to other sections are provided when necessary.
7.1 Drive internal defects/errors
During the initial drive format operation at the factory, media defects are identified, tagged as being unusable,
and their locations recorded on the drive primary defects list (referred to as the “P’ list and also as the ETF
defect list). At factory format time, these known defects are also reallocated, that is, reassigned to a new place
on the medium and the location listed in the defects reallocation table. The “P” list is not altered after factory
formatting. Locations of defects found and reallocated during error recovery procedures after drive shipment
are listed in the “G” list (defects growth list). The “P” and “G” lists may be referenced by the initiator using the
Read Defect Data command.
Details of the SCSI commands supported by the drive are described in the Fibre Channel Interface Manual.
Also, more information on the drive Error Recovery philosophy is presented in the Fibre Channel Interface
Manual.
7.2 Drive er ror recov ery procedures
When an error occurs du ri ng dr ive ope ration, the drive, if program med t o do so, pe rfor ms er ror recove ry pro cedures to attempt to reco ver the dat a. T he err or r ecover y proce dure s used depend on the options pre viously set
in the Error Recovery Parameters mode page. Error recovery and defect management may involve using several SCSI commands described in the Fibre Channel Interface Manual. The drive implements selectable error
recovery time limits required in video applications.
The error r ecover y sche me suppo rted by t he d ri ve p rovide s a way to contr ol th e to tal error recovery time for the
entire command in addition to controlling the recovery level for a single LBA. The total amount of time spent in
error recovery for a command can be limited using the Recovery Time Limit bytes in the Error Recovery mode
page. The total amount of time spent in error recovery for a single LBA can be limited using the Read Retry
Count or Write Retry Count bytes in the Error Recovery mode page.
The drive firmware error recovery algorithms consists of 11 levels for read recoveries and five levels for write.
Each level may consist of multiple steps, where a step is defined as a recovery function involving a single reread or re-write attempt. The maximum level used by the drive in LBA recovery is determined by the read and
write retry counts.
Page 44
36
NL35 Series FC Product Manual, Rev. D
Table 12 equates the read and write retry count with the maximum possible recovery time for read and write
recovery of individual LBAs. The times given do not include time taken to perform reallocations. Reallocations
are performed when the ARRE bit (for reads) or AWRE bit (for writes) is one, the RC bit is zero, and the recovery time limit for the command has not yet been met. Time needed to perform reallocation is not counted
against the recovery time limit.
When the RC bit is one, reallocations are disabled even if the ARRE or AWRE bits are one. The drive will still
perform data recovery actions within the limits defined by the Read Retry Count, Write Retry Count, and
Recovery Time Limit parameters. However, the drive does not report any unrecovered errors.
Table 12: Read and write retry count maximum recovery times
Read retry
1
count
0 108.3 0 50.0
1 125.0 1 75.0
2 424.8 2 116.6
3 474.8 3 141.6
4 541.5 4 249.9
5 599.8 5 308.2 (default)
6 666.4
7 841.3
8 958.0
9 1091.2
10 1166.2
11 2066.1 (default)
Maximum recovery time per
LBA (cumulative, msec)
Write retry
1
count
Maximum recovery time per
LBA (cumulative, msec)
[1] These values are subject to change.
Setting these retry counts to a value below the default setting could result in an increased unrecovered
error rate which may exceed the value given in this product manual. A setting of zero (0) will result in the
drive not performing error recovery.
For example, suppose the Read/Write Recovery page has the RC bit set to 0, read retry count set to 4,
and the recovery time limit field (Mode Sense page 01, bytes 10 and 11) set to FF FF hex (maximum). A
four LBA Read command is allowed to take up to 541.5 msec recovery time for each of the four LBAs in
the command. If the recovery time limit is set to 00 C8 hex (200 msec decimal) a four LB A read comm and
is allowed to take up to 200 msec for all error recovery within that command. The use of the Recovery
Time Limit field allows finer granularity on control of the time spent in error recovery. The recovery time
limit only starts counting when the drive is executing error recovery and it restarts on each command.
Therefore, each command’s total recovery time is subject to the recovery time limi t. Note: A recovery time
limit of 0 will use the drive’s default value of FF FF. Minimum recovery time limit is achieved by setting the
Recovery Time Limit field to 00 01.
Page 45
NL35 Series FC Product Manual, Rev. D
37
7.3 FC-AL system errors
Information on the reporting of operational errors or faults across the interface is given in the Fibre Channel
Interface Manual. The FCP Response returns information to the host about numerous kinds of errors or faults.
The Receive Diagnostic Results reports the results of diagnostic operations performed by the drive.
Status returned by the drive to the initiator is described in the Fibre Channel Interface Manual. Status reporting
plays a role in systems err or manag ement and its use in that resp ect is d escribed in se ctions whe re t he va rious
commands are discussed.
7.4 Background Media Scan
Background Media Scan (BGMS) is a self-initiated media scan. It performs sequential reads across the entire
pack of the media while the drive is idle. In RAID arrays, BGMS allows hot spare drives to be scanned for
defects prior to being put into service by the host system. On regualr duty drives, if the host system makes use
of the BGMS Log Page, it can avoid placing data in suspect locations on the media. Unrecovered error sites
found during BGMS will be logged and recovered error sites will be logged or reallocated per ARRE/AWRE
settings.
With BGMS, the host system can consume less power and system overhead by only checking BGMS status/
results rather th an tying up th e bus a nd consu ming p ow er in the pr ocess o f host- initiated media scanning activ ity.
Since the background scan functions are only done during idle periods, BGMS causes a negligible impact to
system performance. Background media scan will begin after 500ms of idle time. Other features that normally
use idle time to function will function normally because BGMS functions for bursts of 800ms and then suspends activity to allow other backg roun d functi ons to opera te. Addi tionall y, BGMS operates in segments of 400
block reads, checking for host commands upon completion of each of the block segments.
The BGMS function will complete any BGMS-initiated error recovery prio r to returning to se rvice host-initiated
commands. Overhead associ ate d with a retu rn to host- servic ing activity from BGMS only impacts the first command that interrupted BGMS. This results in a typical delay of about 4 ms.
7.4.1 Media Pre-Scan
Media Pre-Scan is an option al featur e that al lows the drive to hand l e unreco vered media err ors tha t would ot herwise have been found by the host system during critical data accesses early in the integration process at
customer sites. This should reduce integration DPPM (defective parts per million) by identifying and repairing
media errors that arose during shipping and handling. Media Pre-Scan replaces all host-initiated Write commands with Write-Verify commands when the drive is accessing areas of the media yet untouched by BGMSinitiated scanning activity.
The drive will attempt to run BGMS on the entire pack of the drive. This will result in increasingly large portion
so fthe drive having been accesed, provided there is adequate idle time to allow BGMS to run. During the PreScan period, all Write commands that are in un-BGMS-scanned areas are converted to Write-Verify commands. To expedite the scan of the full pack and the subsequenty exit from the Pre-Scan period, BGMS will
begin immediately when the drive goes to idle during the Pre-Scan period, as opposed to waiting 500ms as is
done under non-Pre-Scan conditions.
Page 46
38
NL35 Series FC Product Manual, Rev. D
Page 47
NL35 Series FC Product Manual, Rev. D
39
8.0 Installation
NL35 Series disc drive installation is a plug-and-play process. There are no jumpers, switches, or terminators
on the drive. Simply plug the drive into the host’s 40-pin Fibre Channel backpanel connector (FC-SCA)—no
cables are required. See Section 9.5 for additional information about this connector.
Use the FC-AL interface to select drive ID and all option configurations for devices on the loop.
If multiple devices are on the same FC-AL and physical addresses are used, set the device selection ID s (SEL
IDs) on the backp anel so that no two devices have th e sam e select ion ID. T his is ca lled the har d assi gn ed arbi trated loop physical ad dress ( AL_PA). There are 125 AL_PAs available (see Table 32). If you set the AL _PA on
the backpanel to any value other than 0, the device plugged into the backpanel’s SCA connector inherits this
AL_PA. In the event you don’t successfully assign unique hard addresses (and therefore have duplicate selection IDs assigned to two or more devices), the FC-AL generates a message indicating this condition. If you set
the AL_PA on the backpanel to a value of 0, the system issues a unique soft-assigned physical address automatically.
Loop initialization is the process used to verify or obtain an address. The loop initialization process is performed when pow er is applied to the drive, whe n a device is added or removed from the F ibre Cha nnel loop , or
when a device times out attempting to win arbitration.
• Set all option selections in the connector prior to applying power to the drive. If you change options after
applying power to the drive, recycle the drive power to activate the new settings.
• It is not necessary to low-level format this drive. Default configuration units are shipped from the factory lowlevel formatted in 5 12-b yte logi cal blocks. You need to reformat the drive on ly if yo u want to se lect a di f fer ent
logical block size.
8.1 Drive ID/option selection
All drive options are made through the interface connector (J1). Table provides the pin descriptions for the 40pin Fibre Channel single connector (J1).
8.2 Drive or ientat ion
The drive may be mounted in any orientation. All drive performance characterizations, however, have been
done with the drive in horizontal (discs level) and vertical (drive on its side) orientations, which are the two preferred mounting orientations.
Page 48
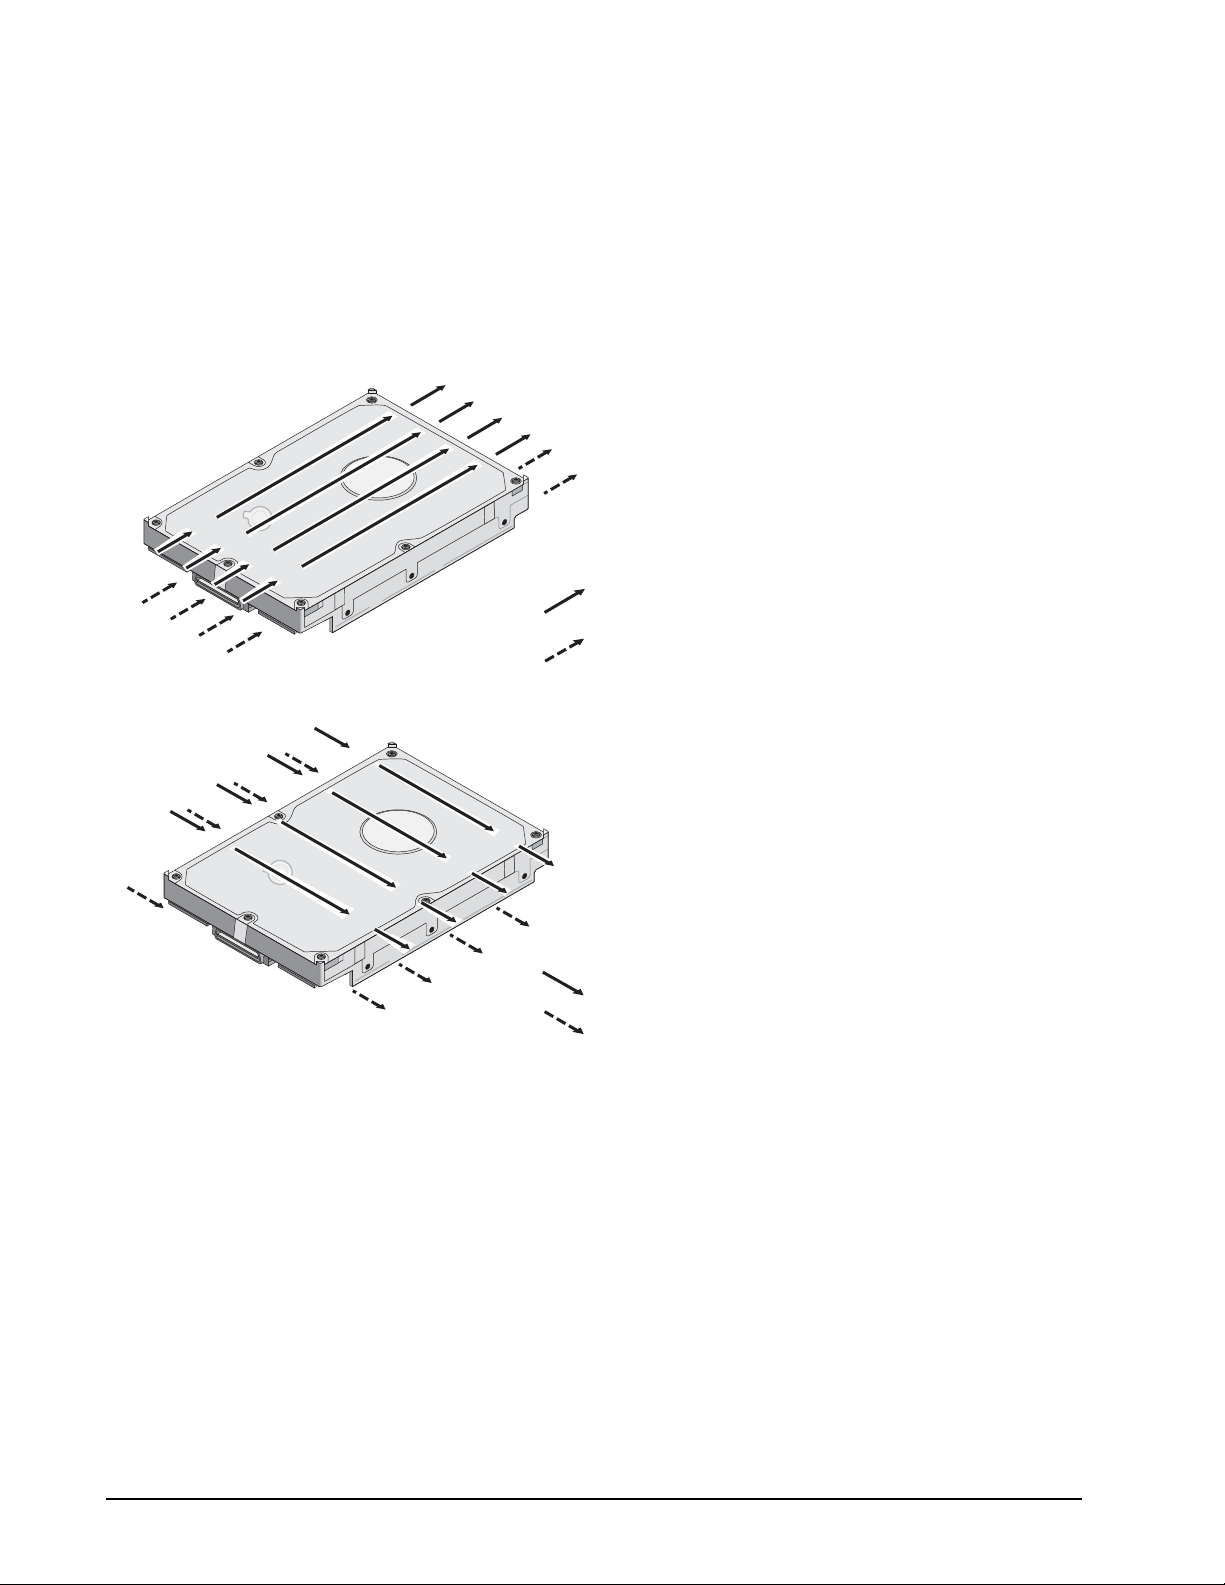
40
NL35 Series FC Product Manual, Rev. D
8.3 Cooling
The host enclosure must provide heat removal from the drive. You should confirm that the host enclosure is
designed to ensure that the drive operates within the temperature measurement guidelines described in Section 6.4.1. In some cases, forced airflow may be required to keep temperatures at or below the temperatures
specified in Section 6.4.1.
If forced air is necessary, possible air-flow patterns are shown in Figure 7. The air-flow patterns are created by
fans either forcing or drawing air as shown in the illustrations. Conduction, convection, or other forced air-flow
patterns are acceptable as long as the temperature measurement guidelines of Section 6.4.1 are met.
Above unit
Note. Air flows in the direction shown (back to front)
or in reverse direction (front to back)
Note. Air flows in the direction shown or
in reverse direction (side to side)
Figure 7. Air flow
Under unit
Above unit
Under unit
Page 49
NL35 Series FC Product Manual, Rev. D
41
8.4 Drive mounting
Mount the drive usi ng the b ottom or side mo unting hol es. If you moun t the d rive u s ing the botto m ho les, ensure
that you do not physically distort the drive by attempting to mount it on a stiff, non-flat surface.
The allowable mounting surface stiffness is 80 lb/in (14.0 N/mm). The following equation and paragraph define
the allowable mounting surface stiffness:
K x X = F < 15lb = 67N
where K is the mounting surface stiffness (units in lb/in or N/mm) and X is the out-of-plane surface distortion
(units in inches or millimeters). The out-of-plane distortion (X) is determined by defining a plane with three of
the four mounting points fixed and evaluating the out-of-plane deflection of the fourth mounting point when a
known force (F) is applied to the fourth point.
Note. Before mounting the drive in any kind of 3.5-inch to 5.25-inch adapter frame, verify with Seagate
Technology that the drive can meet the shock and vibration specifications given herein while
mounted in such an adapter frame. Adapter frames that are available may not have a mechanical
structure capable of mounting the drive so that it can meet the shock and vibration specifications
listed in this manual.
8.5 Grounding
Signal ground (PCBA) and HDA ground are connected together in the drive and cannot be separated by the
user. The equipment in which the drive is mounted is connected directly to the HDA and PCBA with no electrically isolating shock mounts. If it is desired for the system chassis to not be connected to the HDA/PCBA
ground, the systems integrator or user must provide a nonconductive (electrically isolating) method of mounting the drive in the host equipment.
Increased radiated emissions may result if you do not provide the maximum surface area ground connection
between system ground and drive ground. This is the system designer’s and integrator’s responsibility.
Page 50
42
NL35 Series FC Product Manual, Rev. D
Page 51
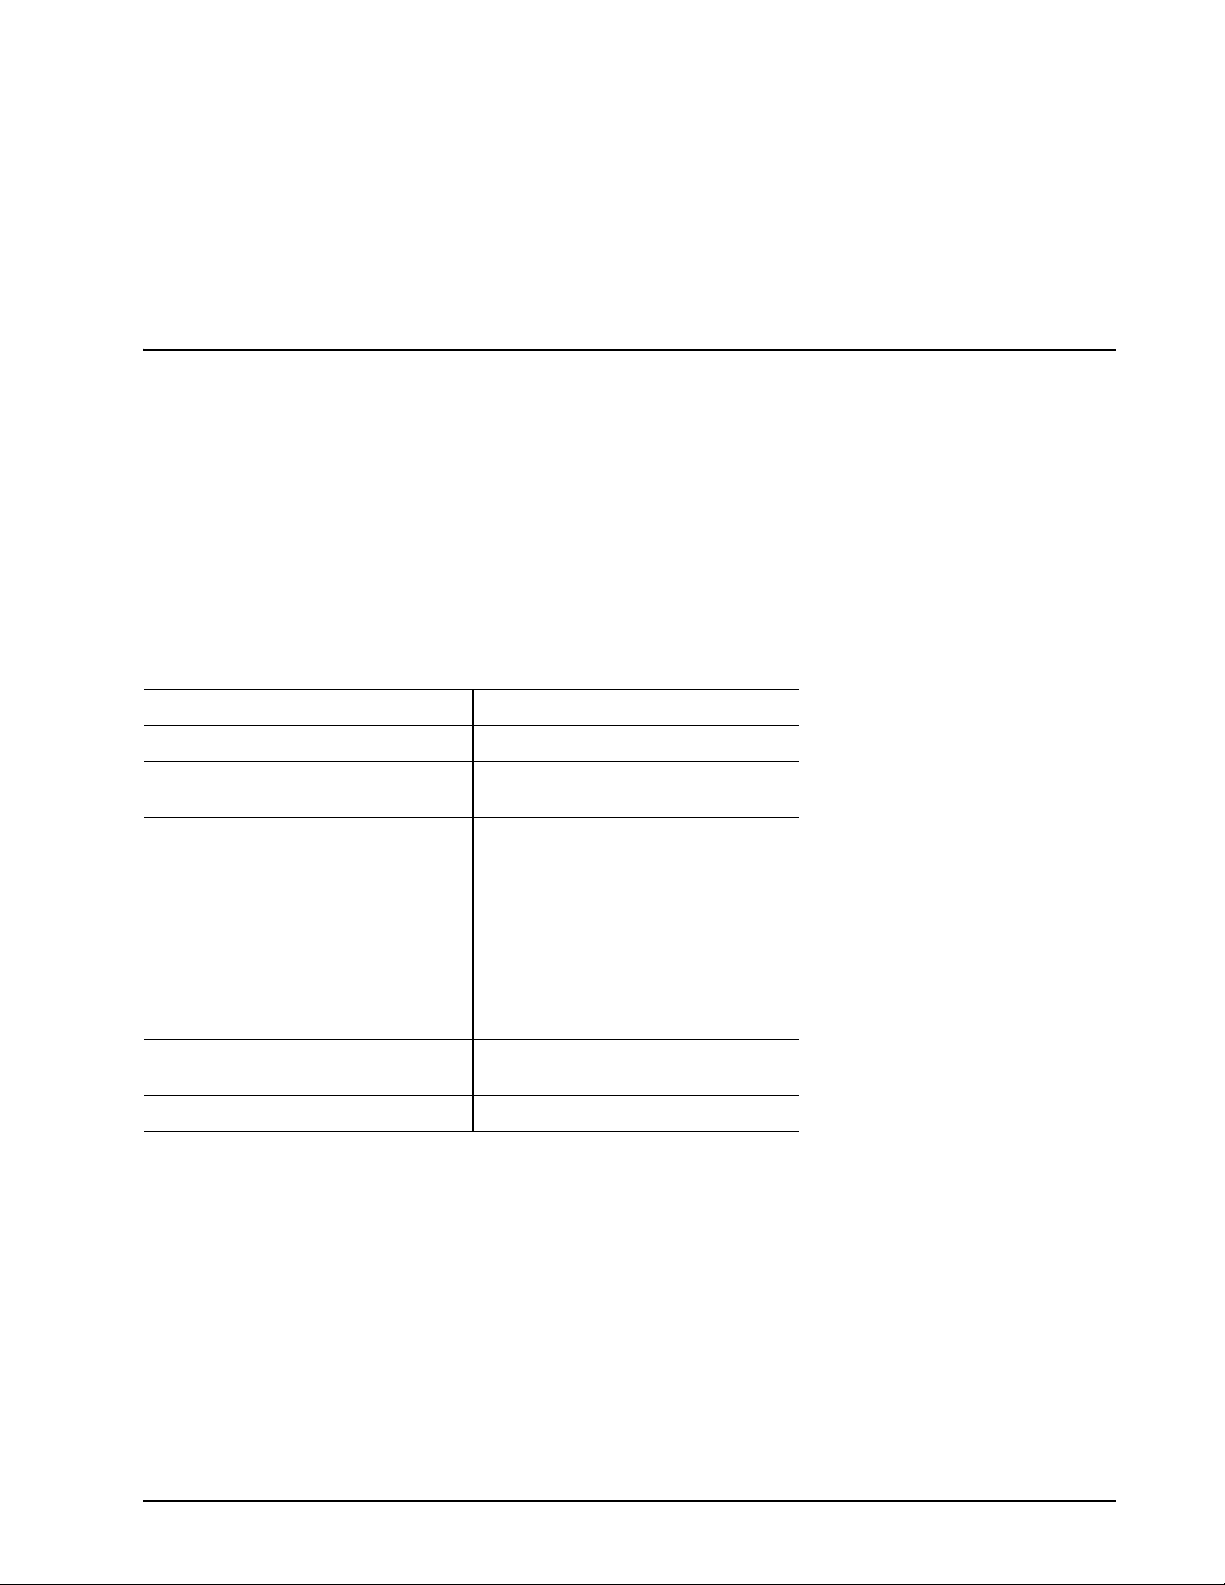
NL35 Series FC Product Manual, Rev. D
43
9.0 Interface requirements
This section partially describes the interface requirements as implemented on NL35 Series drives. Additional
information is provided in the Fibre Channel Interface Manual (part number 77767496).
9.1 FC-AL feat ures
This section lists the Fibre Channel-specific features supported by NL35 Series drives.
9.1.1 Fibre Channel link service frames
Table 13 lists the link services supported by NL35 Series drives.
T a ble 13: Link services support ed
Type of frame Link service
Basic link service frames Abort Sequence (ABTS)
Basic link service reply frames Basic_Accept (BA_ACC)
Extended link service frames N_Port Login (PLOGI)
Extended link service reply frames Accept (ACC)
Fibre Channel Services Register FC-4 Types (RFT_ID)
Basic_Reject (BA_RJT)
Fabric Login (FLOGI)
Logout (LOGO)
Process Login (PRLI)
Process Logout (PRLO)
Read Link Status (RLS)
Fabric Address Notification (FAN)
Port Discovery (PDISC)
Address Discovery (ADISC)
Third-party Process Logout (TRPLO)
Link Service Reject (LS_RJT)
Page 52
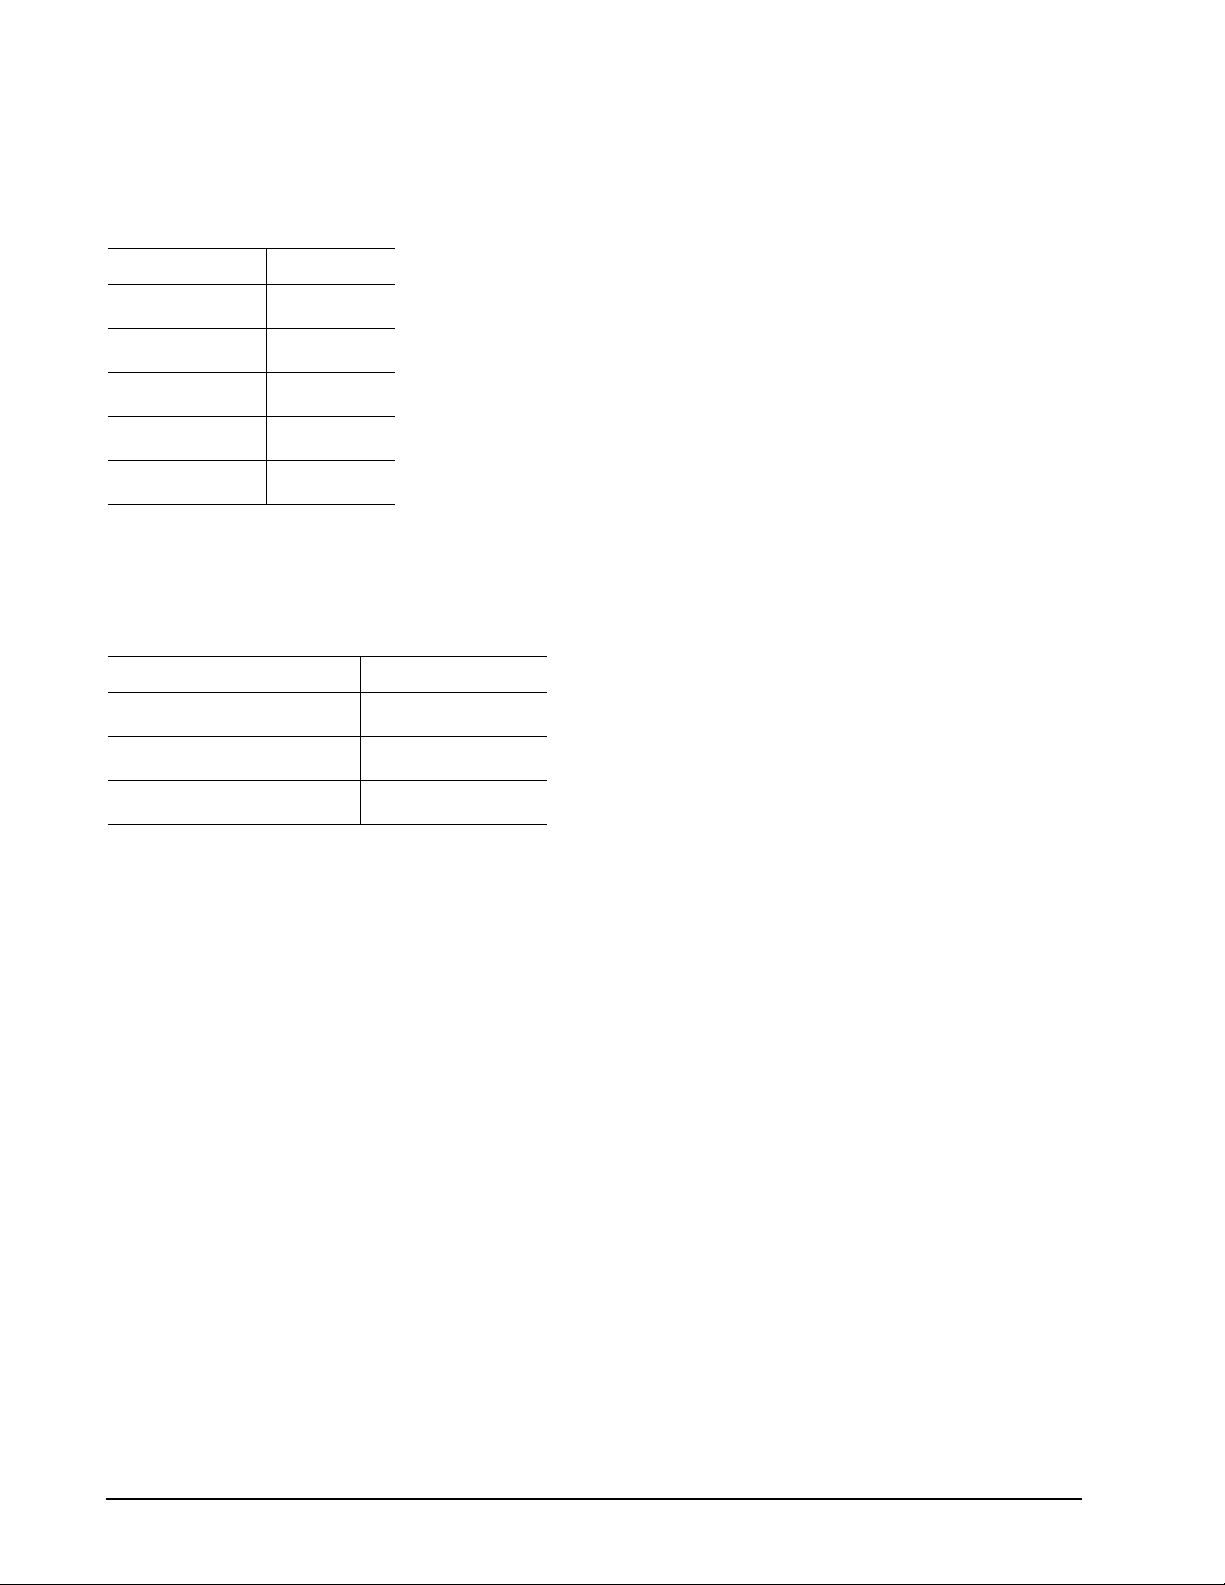
44
NL35 Series FC Product Manual, Rev. D
9.1.2 Fibre Channel task management functions
Table 14 lists the Fibre C hann el S CSI Fibre C han nel P roto col (F C S CSI FCP ) t ask mana geme nt fun cti ons su pported.
Table 14: Fibre Channel SCSI FCP task management functions
T ask name Supported
Term inate task
Clear ACA
Target reset
Clear task set
Abort task set
No
No
Yes
Yes
Yes
9.1.3 Fibre Channel task management responses
Table 15 lists the FC SCSI FCP response codes returned for task management functions supported.
Table 15: FC SCSI FCP response codes
Function na m e Response c ode
Function complete
Function not supported
Function reject
00
04
05
Page 53
NL35 Series FC Product Manual, Rev. D
45
9.1.4 Fibre Channel port login
Table 16 identifies the required content of the N_Port Login (PLOGI) payload from an initiator.
T a ble 16: N_Port login (PLOGI) payload
Bytes
0-15 03 00 00 00 XX XX BB BB CF XX FS FS XX XX XX XX Common
16-31 XX XX XX XX PN PN PN PN PN PN PN PN NN NN NN NN
32-35 NN NN NN NN
36-47 XX XX XX XX XX XX XX XX XX XX XX XX Class 1
48-51 XX XX XX XX
52-63 XX XX XX XX XX XX XX XX XX XX XX XX Class 2
64-67 XX XX XX XX
68-79 SO SO IC IC XX XX FS FS XX CS XX XX Class 3
80-83 OS OS XX XX
84-95 XX XX XX XX XX XX XX XX XX XX XX XX Reserved
96-99 XX XX XX XX
100-111 XX XX XX XX XX XX XX XX XX XX XX XX Vendor
112-115 XX XX XX XX Version
X Indicates a four-bit (hex) field is not checked.
x Indicates a single bit is not checked.
BB BB-Credit. This field is not checked. The FC-AL drive uses BB-Credit of zero (0).
CF Common features. This binary field selects the common features requested by the initiator login.
MSB Continuously increasing offset Must = 1
Random relative offset Not checked. Port Login Accept will return a 0—not supported.
Valid version level x
N_Port/F_Port Must = 0, N_Port
Alternate credit model Must = 1
Other bits reserved xxx XX
FS Receive buffer field size. The FS field in the common and Class 3 parameters is checked for the range 128 < FS < 2,112 and a
multiple of four bytes. For multiple frame sequences, all frames but the last frame of the sequence must be this size. Only the
receive buffer field size in the Class 3 parameters is used.
PN Port name (initiator’s)—saved with the login parameters. If a change of the port name/AL_PA address association is detected
during a Port DISCovery, and implicit logout occurs and the initiator returns a LS_RJT.
NN Node name. The node name is not checked or saved by the drive.
SO Service options Class 3 only.
MSB Class valid Must = 1
Intermix x
Stacked connection req. xx
Sequential delivery x
Other bits reserved xxx XX
IC Initiator control
MSB XID reassign xx
Proc Assc 10 or 11 causes the login to be rejected. Other values are accepted.
Other bits XXX
CS Concurrent sequences Must be a value greater than 0.
OS Open sequences per exchange Must be a value greater than 0.
Page 54
46
NL35 Series FC Product Manual, Rev. D
9.1.5 Fibre Channel port login accept
Table 17 identifies the N_Port Login access payload values.
Table 17: N_Port Login Accept (ACC) payload
Bytes
0-15 02 00 00 00 20 20 00 00 88 00 FS FS 00 FF 00 01 Common
16-31 00 00 01 F4 20 PP 00 20 37 UI UI UI 20 00 00 20
32-35 37 UI UI UI
36-47 00 00 00 00 00 00 00 00 00 00 00 00 Class 1
48-51 00 00 00 00
52-63 00 00 00 00 00 00 00 00 00 00 00 00 Class 2
64-67 00 00 00 00
68-79 80 00 00 00 00 00 FS FS 00 FF 00 00 Class 3
80-83 00 01 00 00
84-95 00 00 00 00 00 00 00 00 00 00 00 00 Reserved
96-99 00 00 00 00
100-111 00 00 00 00 00 00 00 00 00 00 00 00 Vendor 112-115 00 00 00 00 Version
FS Receive buffer field size. The drive returns and uses the receive buffer size from the N_Port Login Class 3 receive
buffer.
UI U nique identifier. This 24-bit field is uniquely assigned to the drive. This same UI appears in the Port Name and
Node Name fields.
PP Port identifier field.
01 P_LOGI received on Port A.
02 P_LOGI received on Port B.
9.1.6 Fibre Channel Process Login
Table 18 lists the process login payload data.
Table 18: Process Login (PLRI) payload
Bytes
0-15 20 10 00 14 08 00 20 00 XX XX XX XX XX XX XX XX
16-19 00 00 00 22
XX Indicates fields that are not used.
Page 55
NL35 Series FC Product Manual, Rev. D
47
9.1.7 Fibre Channel Process Login Accept
Table 19 lists NL35 Series process login accept payload data.
Table 19: Process Login Accept (ACC) payload
Bytes
0-15 02 10 00 14 08 00 21 00 00 00 00 00 00 00 00 00
16-31 00 00 00 12
9.1.8 Fibre Channel fabric login
Table 20 lists the fabric login payload from the drive.
Table 20: Fabric Login (FLOGI) payload
Bytes
0-15 04 00 00 00 20 20 00 00 08 00 08 40 00 00 00 00 Common
16-31 00 00 02 F4 20 PP 00 20 37 UI UI UI 02 00 00 20
32-35 37 UI UI UI
36-47 00 00 00 00 00 00 00 00 00 00 00 00 Class 1
48-51 00 00 00 00
52-63 00 00 00 00 00 00 00 00 00 00 00 00 Class 2
64-67 00 00 00 00
68-79 80 00 00 00 00 00 08 40 00 00 00 00 Class 3
80-83 00 00 00 00
84-95 00 00 00 00 00 00 00 00 00 00 00 00 Reserve
96-99 00 00 00 00
100-111 00 00 00 00 00 00 00 00 00 00 00 00 Vendor 112-115 00 00 00 00 Version
UI Unique identifier. This 24-bit field is uniquely assigned to the drive. This same UI appears in the Port Name and Node Name
fields.
PP Port identifier field.
01 FLOGI originated on Port A.
02 FLOGI originated on Port B.
d
Page 56
48
NL35 Series FC Product Manual, Rev. D
9.1.9 Fibre Channel fabric accept login
Table 20 lists the required content of the Fabric Login Accept (ACC) payload from the fabric.
Table 21: Fabric Login Accept (ACC) payload
Bytes
0-15 02 00 00 00 XX XX BB BB CF XX FS FS R_ A_ T0 V_ Common
16-31 E_ D_ T0 V_ PN PN PN PN PN PN PN PN NN NN NN NN
32-35 NN NN NN NN
36-47 XX XX XX XX XX XX XX XX XX XX XX XX Class 1
48-51 XX XX XX XX
52-63 XX XX XX XX XX XX XX XX XX XX XX XX Class 2
64-67 XX XX XX XX
68-79 SO SO xx xx XX XX FS FS XX xx XX XX Class 3
80-83 OS OS XX XX
84-95 XX XX XX XX XX XX XX XX XX XX XX XX Reserve
d
96-99 XX XX XX XX
100-111 XX XX XX XX XX XX XX XX XX XX XX XX Vendor 112-115 XX XX XX XX Version
X Indicates a four-bit (hex) field is not checked.
x Indicates a single bit is not checked.
BB BB-Credit. This field is not checked. The FC-AL drive uses BB-Credit of zero (0).
CF Common features. This binary field selects the common features requested by the fabric login.
MSB Continuously increasing offset x
Random relative offset x
Valid version level x
N_Port/F_Port Must = 1, F_Port
Alternate credit model Must = 1
Other bits reserved xxx XX
FS Receive buffer field size. The FS field in the common and Class 3 parameters is checked for the range 128 < FS < 2,112 and a
multiple of four bytes. The receive buffer field size in the Class 3 parameters is used. The drive uses the lower FS of Fabric
Login Accept or N_Port Login when sending frames to an initiator.
PN Port Name. The fabric port name is saved with the login parameters. If a change of the port name is detected during a FAN, an
implicit logout occurs and a LS_RJT is returned to the fabric.
NN Node Name. The drive does not check or save the node name.
SO Service Options—Class 3 only.
MSB Class valid Must = 1
Intermix x
Stacked connection req. xx
Sequential delivery Must = 1
Other bits reserved xxx XX
Page 57
NL35 Series FC Product Manual, Rev. D
49
9.1.10 Fibre Channel Arbitrated Loop options
Table 22 lists the FC-AL options supported by NL35 Series drives.
Table 22: FC-AL options supported
Option Supported
OPEN Half Duplex Accepted from another device.
OPEN Full Duplex Sent to open another device.
Private Loop Y es
Public Loop Yes
Old Port State No
Loop Position Yes
Loop Position Report Yes
Accepted from another device.
9.2 Dual port support
NL35 Series drives have two independent FC-AL ports. These ports may be connected on independent loops
or on the same loop. Port A and Port B may be connected in any order or combination.
• If both ports ar e conn ected on i nde pend ent loo ps and h ard a ddre ssi ng is use d, the driv e in terfa ce add ress i s
selected through the interface connector, both ports will seek the same loop address. If no conflict, both
ports will have the same loop address.
• If both ports are connected in the same loop and hard addressing is used, at least one port will attempt taking a soft address to prevent an address conflict.
Note. When a NL35 Series drive is connected in loops with previous Seagate FC drive products:
Barracuda 4LP FC (ST32171FC, ST34371FC, and ST34571FC)
Barracuda 9FC (ST19171FC)
Cheetah 4LP FC (ST34501FC)
Cheetah 9FC (ST19101FC)
the connection of Port A and B for these products must follow the requirements in their product manuals.
Subject to buffer availability, the NL35 Series drives support:
• Concurrent port transfers—The drive supports receiving transfers on both ports at the same time when the
ports are on independent loops.
• Full duplex—The drive supports sending FCP_Data, FCP_RSP, FCP_XFR_RDY and ELS transfers while
receiving frames on both ports.
Page 58
50
NL35 Series FC Product Manual, Rev. D
9.3 SCSI commands supported
Table 23 lists the SCSI commands supported by NL35 Series drives.
T a bl e 23: Supported com ma nds
Command code Supporte d [ 4 ] Command name
00h
01h
03h
04h
07h
08h
0Ah
0Bh
12h
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Test unit ready
Rezero unit
Request sense
Extended sense
Field pointer bytes
Actual retry count bytes
Format unit [1]
Reassign blocks
Read
Write
Seek
Inquiry
Vital product data page (00h)
Unit serial number page (80h)
15h
16h
17h
18h
Y
Y
Y
Y
Y
Y
Y
Y
N
N
Y
N
Implemented operating def. page (81h)
IDevice identification page (83h)
Firmware numbers page (C0h)
Date code page (C1h)
Jumper settings page (C2h)
Device behavior page (C3h)
Mode select (same pages as Mode Sense command shown below) [3]
Reserve
3rd party reserved
Extent reservation
Release
Copy
Page 59
NL35 Series FC Product Manual, Rev. D
51
T a bl e 23: Supported com ma nds (continued)
Command code Supporte d [ 4 ] Command name
1Ah
1Bh
1Ch
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
Mode sense
Unit attention page (00h)
Error recovery page (01h)
Disconnect/reconnect control (page 02h)
Format page (03h)
Rigid disc drive geometry page (04h)
Verify error recovery page (07h)
Caching parameters page (08h)
Fibre Channel interface control page (19h)
Control mode page (0Ah)
Power control page (1Ah)
Information exceptions control page (1Ch)
Start unit/stop unit
Receive diagnostic results
1Dh
25h
28h
2Ah
Y
Y
Y
Y
Y
Y
Y
Y
Y
Y
N
Y
Y
Y
Supported diagnostics pages
Translate page
Enclosure services page
Send diagnostics page
Supported diagnostics pages
Translate page
Read capacity
Read extended
Disable page out
Force unit access
Relative address
Write extended
Disable page out
Force unit access
Page 60
52
NL35 Series FC Product Manual, Rev. D
T a bl e 23: Supported com ma nds (continued)
Command code Supporte d [ 4 ] Command name
2Bh
2Eh
2Fh
30h
31h
32h
33h
N
Y
Y
Y
Y
N
Y
Y
Y
N
N
N
N
N
Relative address
Seek extended
Write and verify
Disable page out
Byte check
Relative address
Verify
Disable page out
Byte check
Relative address
Search data high
Search data equal
Search data low
Set limits
34h
35h
36h
37h
39h
3Ah
3Bh
N
Y
N
Y
N
N
Y
Y
Y
N
Y
N
Y
Y
Prefetch
Synchronize cache
Lock-unlock-cache
Read defect data
Compare
Copy and verify
Write buffer
Write combined header and data mode (0)
Write data mode (2)
Download microcode mode (4)
Download microcode and save modes (5)
Download microcode with offsets mode (6)
Download microcode with offsets and save mode (7)
Firmware download option [2]
Page 61
NL35 Series FC Product Manual, Rev. D
53
T a bl e 23: Supported com ma nds (continued)
Command code Supporte d [ 4 ] Command name
3Ch
3Eh
3Fh
40h
41h
42-4Bh
4Ch
4Dh
Y
Y
Y
Y
Y
Y
N
Y
N
N
N
Y
Y
Y
Read buffer
Read combined header and data mode (0)
Read data mode (2)
Read descriptor mode (3)
Read long
Write long
Change definition
Write same
PBdata
LBdata
Not used
Log Select
Log Sense
Supported Log page (00h)
4E-4Fh
50h
51h
52h
Y
Y
N
Y
Y
Y
N
Y
Y
Y
N
N
N
N
Write Error Counter page (02h)
Read Error Counter page (03h)
Read Reverse Error Counter page (04h)
Verify Error Counter page (05h)
Non-medium Error Counter page (06h)
Temperature page (0Dh)
Application Client page (0Fh)
Self Test Results page (10h)
Cache Statistics Counter page (37h)
Factory Log page (3Eh)
Not used
XD write
XP write
XD read
Page 62
54
NL35 Series FC Product Manual, Rev. D
T a bl e 23: Supported com ma nds (continued)
Command code Supporte d [ 4 ] Command name
53-54h
55h
56h
57h
58-59h
5Ah
5B-5Dh
5E
5F
60-7Fh
80h
81h
N
Y
Y
Y
N
Y
N
Y
N
A
A
N
N
N
Not used
Mode Select (10) [3]
Reserved (10)
3rd party reserve
Extent reservation
Released (10)
Not used
Mode Sense (10) [3]
Not used
Persistent reserve in
Persistent reserve out
Not used
XD write extended
Rebuild
82h
83-8Fh
C0-DFh
EO-FFh
N
N
N
N
Regenerate
Not used
Not used
Not used
[1] NL35 Series drives can format to 512, 520, 524, and 528 bytes per logical block.
[2] Warning. Power loss during flash programming can result in firmware corruption. This usually makes the
drive inoperable.
[3] Reference Mode Sense command 1Ah for mode pages supported.
[4] Y = Ye s. Command is supported.
N = No. Command is not supported.
A = Support is available on special request.
Page 63
NL35 Series FC Product Manual, Rev. D
55
9.3.1 Inquiry data
Table 24 lists the Inquiry command data that the drive should return to the initiator per the format given in the
Fibre Channel Interface Manual.
Table 24: NL35 Series inquiry data
Bytes Data (hex)
0-15 00 00 ** 12 8B 00 PP 0A 53 45 41 47 41 54 45 20 Vendor ID
16-31 [53 54 33 35 30 30 30 37 31 46 43] 20 20 20 20 20 Product ID
32-47 R# R# R# R# S# S# S# S# S# S# S# S# 00 00 00 00
48-63 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
64-79 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
80-95 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
96-111 00 43 6F 70 79 72 69 67 68 74 20 28 63 29 20 32* *Copyright
112-127 30* 30* 36* 20 53 65 61 67 61 74 65 20 41 6C 6C 20 notice
128-143 72 69 67 68 74 73 20 72 65 73 65 72 76 65 64 20
* Copyright year (changes with actual year).
** 02 = SCSI-2 implemented with some SCSI-3 features (default).
03 = The device complies to ANSI X3.301:199x
PP 50 = Inquiry data for an Inquiry command received on Port A.
70 = Inquiry data for an Inquiry command received on Port B.
R# Four ASCII digits representing the last four digits of the product firmware release number.
S# Eight ASCII digits representing the eight digits of the product serial number.
[ ] Bytes 16 through 25 reflect drive model.
9.3.2 Mode Sense data
The Mode Sense command provides a way for the drive to report its operating parameters to the initiator. The
drive maintains four sets of mode parameters:
1. Default values
Default values are hard-coded in the drive firmware stored in flash E-PROM (nonvolatile memory) on the
drive’s PCB. These default values can be changed only by downloading a complete set of new firmware
into the flash E-PROM. An initiator can request and receive from the drive a list of default values and use
those in a Mode Select command to set up new current and saved values, where the values are changeable.
2. Saved values
Saved values are stored on the drive’s media using a Mode Select command. Only parameter values that
are allowed to be chang ed c an b e cha nged by th i s me thod. Pa ram eters in th e save d va lues l ist that are not
changeable by the Mode Select command get their values from default values storage.
When power is applied to the drive, it takes saved values from the media and stores them as current values in volatile memory. It is not possible to change the current values (or the saved values) with a Mode
Select command before the drive achieves operating speed and is “ready.” An attempt to do so results in a
“Check Condition” status.
On drives requiring unique saved values, the required unique saved values are stored into the saved values storage location on the media prior to shipping the drive. Some drives may have unique firmware with
unique default values also.
Page 64
56
NL35 Series FC Product Manual, Rev. D
On standard OEM drives, the saved values are taken from the default values list and store d into the saved
values storage location on the media prior to shipping.
3. Current values
Current values are volatile values bei ng used by the driv e to contro l its operation. A Mod e S elect comm and
can be used to change the values identified as changeable values. Originally, current values are installed
from saved or default values after a power on reset, hard reset, Target Reset, or LIP Reset.
4. Changeable values
Changeable values for m a bit mask, stored in no nvolatil e me mor y, that dictates which of the current values
and saved values can be changed by a Mode Select command. A one (1) indicates the value can be
changed. A zero (0) indicates the value is not changeable. For example, in Table 25, refer to Mode page
81, in the row entitled “CHG.” These are hex numbers representing the changeable values for Mode page
81. Note in colu mns 5 and 6 ( bytes 0 4 an d 05) , th ere is 00h w hich ind ic ates th at in bytes 0 4 an d 05 none of
the bits are changeable. Note also that bytes 06, 07, 09, 10, and 11 are not changeable, because those
fields are all zeros. In byte 02 , hex val u e FF equates to the binary p attern 11111111. If there is a zero in any
bit position in the field, it means that bit is not changeable. Since all of the bits in byte 02 are ones, all of
these bits are changeable.
The changeable values list can only be changed by downloading new firmware into the flash E-PROM.
Note. Because there are often several dif feren t versi on s of dr ive contr ol firm ware in the total population of
drives in the field , the Mode Sense values given in the followi ng ta bles m ay not exactly m atch t hose
of some drives.
The following table s list the values of the dat a bytes returned by the drive in response to the Mode Sense command pages for SCSI implementation (see the Fibre Channel Interface Manual ).
Definitions:
DEF = Default value. Standard OEM drives are shipped configured this way.
CHG = Changeable bits; indicates if default value is changeable.
Page 65
NL35 Series FC Product Manual, Rev. D
57
Table 25: Mode Sense data default and changeable values for ST3500071FC drives
ST3500071FC
Bytes 00 01 02 03 04 05 06 07 08 09 10 11 12 13 14 15 16 17 18 19 20 21 22 23
Mode
Sense
Header
DEF 81 0a c0 0b f f 00 00 00 05 00 f f f f
CHG 81 0a f f f f 00 00 00 00 f f 00 f f f f
DEF 82 0e 80 80 00 00 00 00 00 00 0c 9b 00 00 00 00
CHG 82 0e f f f f 00 00 00 00 00 00 f f f f 00 00 00 00
DEF 83 16 14 9e 00 00 00 2b 00 00 03 d7 02 00 00 01 00 e1 00 60 40 00 00 00
CHG 83 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 84 16 01 df 54 08 00 00 00 00 00 00 00 00 00 00 00 00 00 00 1c 22 00 00
CHG 84 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 87 0a 00 0b f f 00 00 00 00 00 f f f f
CHG 87 0a 0f f f 00 00 00 00 00 00 f f f f
DEF 88 12 14 00 f f f f 00 00 f f f f f f f f 00 03 00 00 00 00 00 00
CHG 88 12 b5 00 00 00 f f f f f f f f 00 00 a0 f f 00 00 00 00 00 00
00 ae 00 10 00 00 00 08 3a 35 29 44 00 00 02 00
<-----------------------------Mode Page 16 Byte Header Data and Parameter Data Bytes--------------------------->
DEF 8a 0a 02 00 00 00 00 00 00 00 27 00
CHG 8a 0a 03 f1 00 00 00 00 00 00 00 00
DEF 99 06 00 00 00 00 00 00
CHG 99 06 00 f f 00 00 00 00
DEF 9a 0a 00 02 00 00 00 05 00 00 00 04
CHG 9a 0a 00 03 f f f f f f f f 00 00 00 00
DEF 9c 0a 10 00 00 00 00 00 00 00 00 01
CHG 9c 0a 9d 0f f f f f f f f f f f f f f f f f
DEF 80 06 00 00 0f 00 00 8c
CHG 80 06 b7 40 0f 00 00 f f
<--- Read capacity data --->
3a 35 29 43 00 00 02 00
Page 66
58
NL35 Series FC Product Manual, Rev. D
Table 26: Mode Sense data default and changeable values for ST3400071FC drives
ST3400071FC
Bytes 00 01 02 03 04 05 06 07 08 09 10 11 12 13 14 15 16 17 18 19 20 21 22 23
Mode
Sense
Header
DEF 81 0a c0 0b f f 00 00 00 05 00 f f f f
CHG 81 0a f f f f 00 00 00 00 f f 00 f f f f
DEF 82 0e 80 80 00 00 00 00 00 00 0c 9b 00 00 00 00
CHG 82 0e f f f f 00 00 00 00 00 00 f f f f 00 00 00 00
DEF 83 16 13 4b 00 00 00 34 00 00 03 54 02 00 00 01 00 e1 00 60 40 00 00 00
CHG 83 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 84 16 01 bd 5d 08 00 00 00 00 00 00 00 00 00 00 00 00 00 00 1c 22 00 00
CHG 84 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 87 0a 00 0b f f 00 00 00 00 00 f f f f
CHG 87 0a 0f f f 00 00 00 00 00 00 f f f f
DEF 88 12 14 00 f f f f 00 00 f f f f f f f f 00 03 00 00 00 00 00 00
CHG 88 12 b5 00 00 00 f f f f f f f f 00 00 a0 f f 00 00 00 00 00 00
00 ae 00 10 00 00 00 08 2e 90 ed d0 00 00 02 00
<-----------------------------Mode Page 16 Byte Header Data and Parameter Data Bytes--------------------------->
DEF 8a 0a 02 00 00 00 00 00 00 00 21 00
CHG 8a 0a 03 f1 00 00 00 00 00 00 00 00
DEF 99 06 00 00 00 00 00 00
CHG 99 06 00 f f 00 00 00 00
DEF 9a 0a 00 02 00 00 00 05 00 00 00 04
CHG 9a 0a 00 03 f f f f f f f f 00 00 00 00
DEF 9c 0a 10 00 00 00 00 00 00 00 00 01
CHG 9c 0a 9d 0f f f f f f f f f f f f f f f f f
DEF 80 06 00 00 0f 00 00 8c
CHG 80 06 b7 40 0f 00 00 f f
<--- Read capacity data --->
2e 90 ed cf 00 00 02 00
Page 67
NL35 Series FC Product Manual, Rev. D
59
9.4 Miscellaneous operating features and conditions
Table 27 lists various features and conditions. A “Y” in the support column indicates the feature or condition is
supported. An “N” in the support column indicates the feature or condition is not supported.
T a ble 27: Miscellaneo us fea tures
Suppor t e d Feature or condition
Y
N
N
N
Y
N
Y
Y
Y
Y
N
Y
FC-AL selective reset
Automatic contingent allegiance
Asynchronous event notification
Synchronized (locked) spindle operation
Segmented caching
Zero latency read
Queue tagging (up to 64 queue tags supported)
Deferred error handling
Parameter rounding (controlled by Round bit in Mode Select page 0)
Reporting actual retry count in Extended Sense bytes 15, 16, and 17
Adaptive caching
SMP = 1 in Mode Select command needed to save RPL and rotational offset bytes
T a ble 28: Miscellaneous st atu s
Supported Status
Y
Y
Y
Y
Y
Y
Y
Y
N
N
Good
Check condition
Condition met/good
Busy
Intermediate/good
Intermediate/condition met/good
Reservation conflict
Task set full
ACA active
ACA active, faulted initiator
Page 68
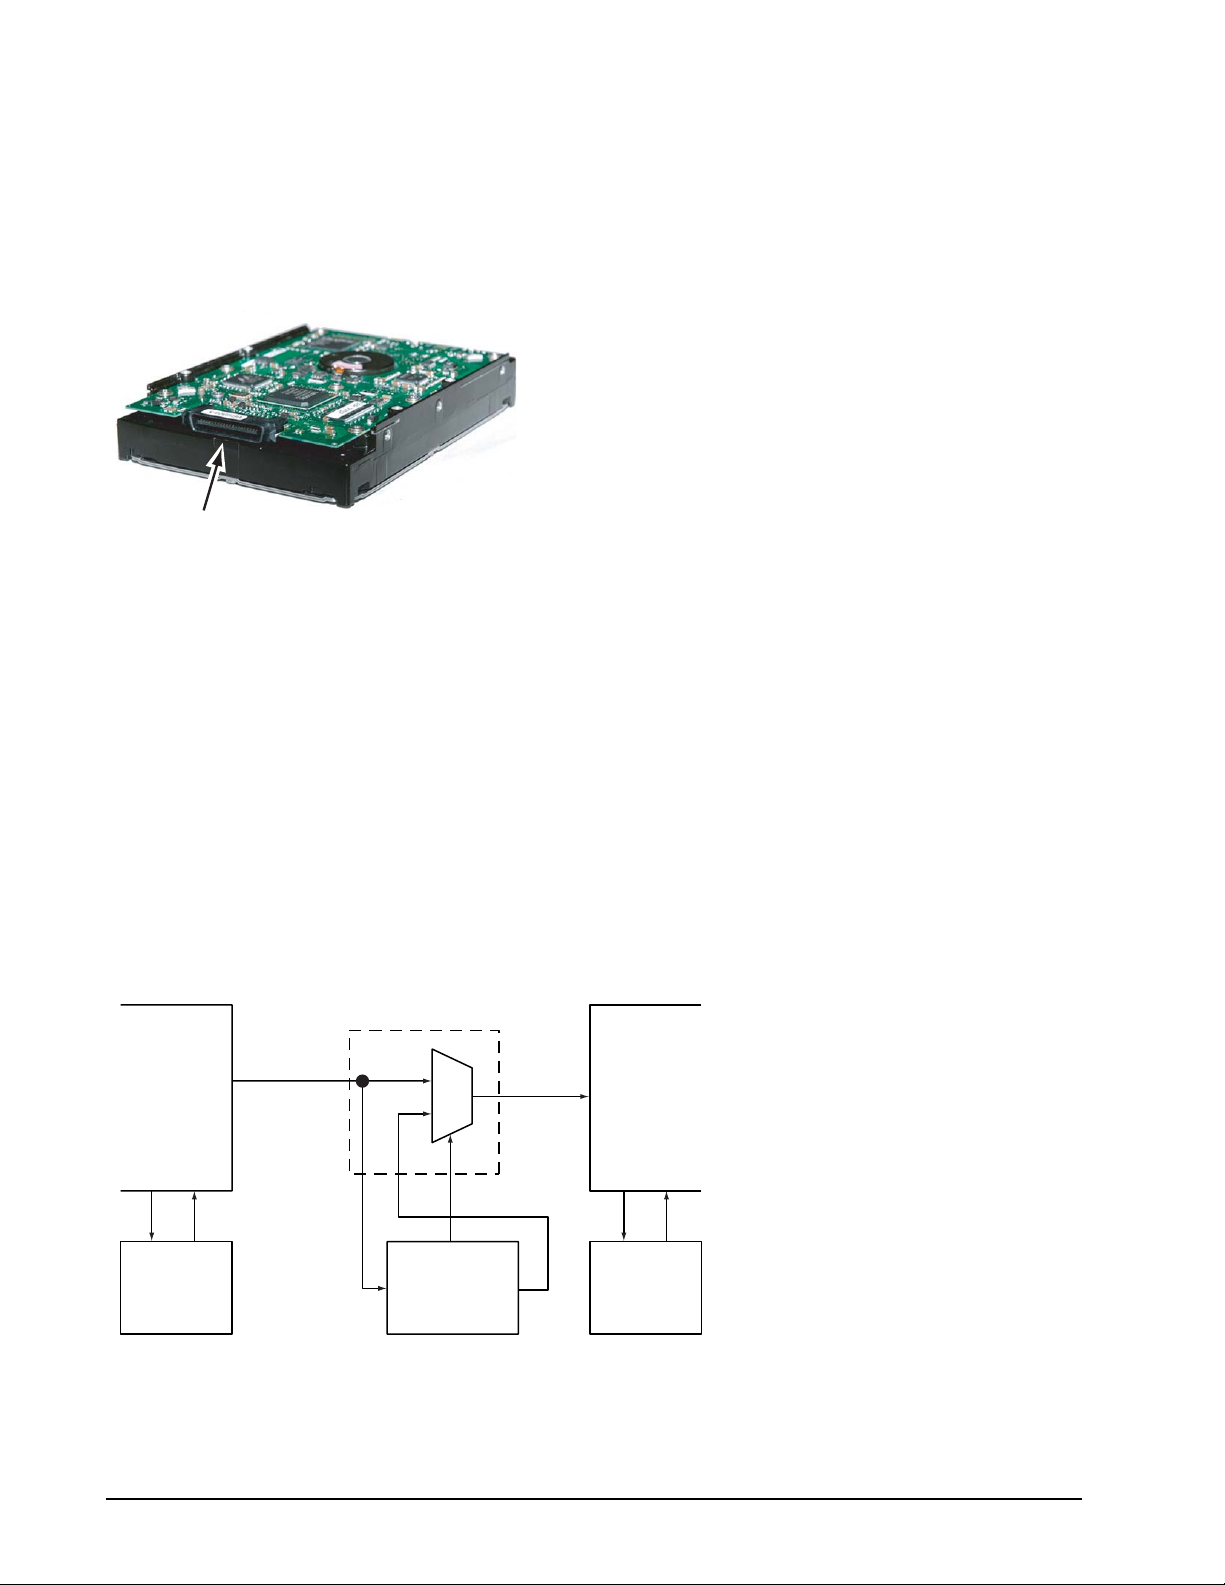
60
NL35 Series FC Product Manual, Rev. D
9.5 FC-AL physical interface
Port Bypass
Figure 8 shows the location of the J1 Fibre Channel single connection attachment (FC-SCA). Figure 10 provides the dimensions of the FC-SCA.
Details of the physical, electrical, and logical characteristics are provided within this section. The operational
aspects of Seagate’s Fibre Channel drives are provided in the Fibre Channel Interface Manual.
Fibre Channel
I/O Connector
Figure 8. Physical interface
9.5.1 Physical character istic s
This section defines physical interface connector.
9.5.1.1 Physical description
FIbre Channel drives may be connected in a loop together or with other compatible FC-AL devices. A maximum of 127 devices may have addresses; however, one of the addresses is reserved for a fabric port switch
device. This means 126 addresses are available for FC-AL devices. More FC-AL compatible devices may
physically reside on the loop, but they will not be functional because they would not be able to obtain valid
addresses.
Port bypass circuits (PBCs) allow devices to be inserted into unpopulated locations or removed from the loop
with loop operation recovery after a brief interruption. These PBCs are located external to the FC-AL device.
Figure 9 shows the relationship between the PBC and FC-AL device.
Circuit
From Previous
Port Bypass
Circuit N–1
Drive N–1
Drive
MUX
Select
SerialInSerial
Drive N
Out
To Next
Drive
Port Bypass
Circuit N+1
Drive N+1
Figure 9. Port bypass circuit physical interconnect
Page 69
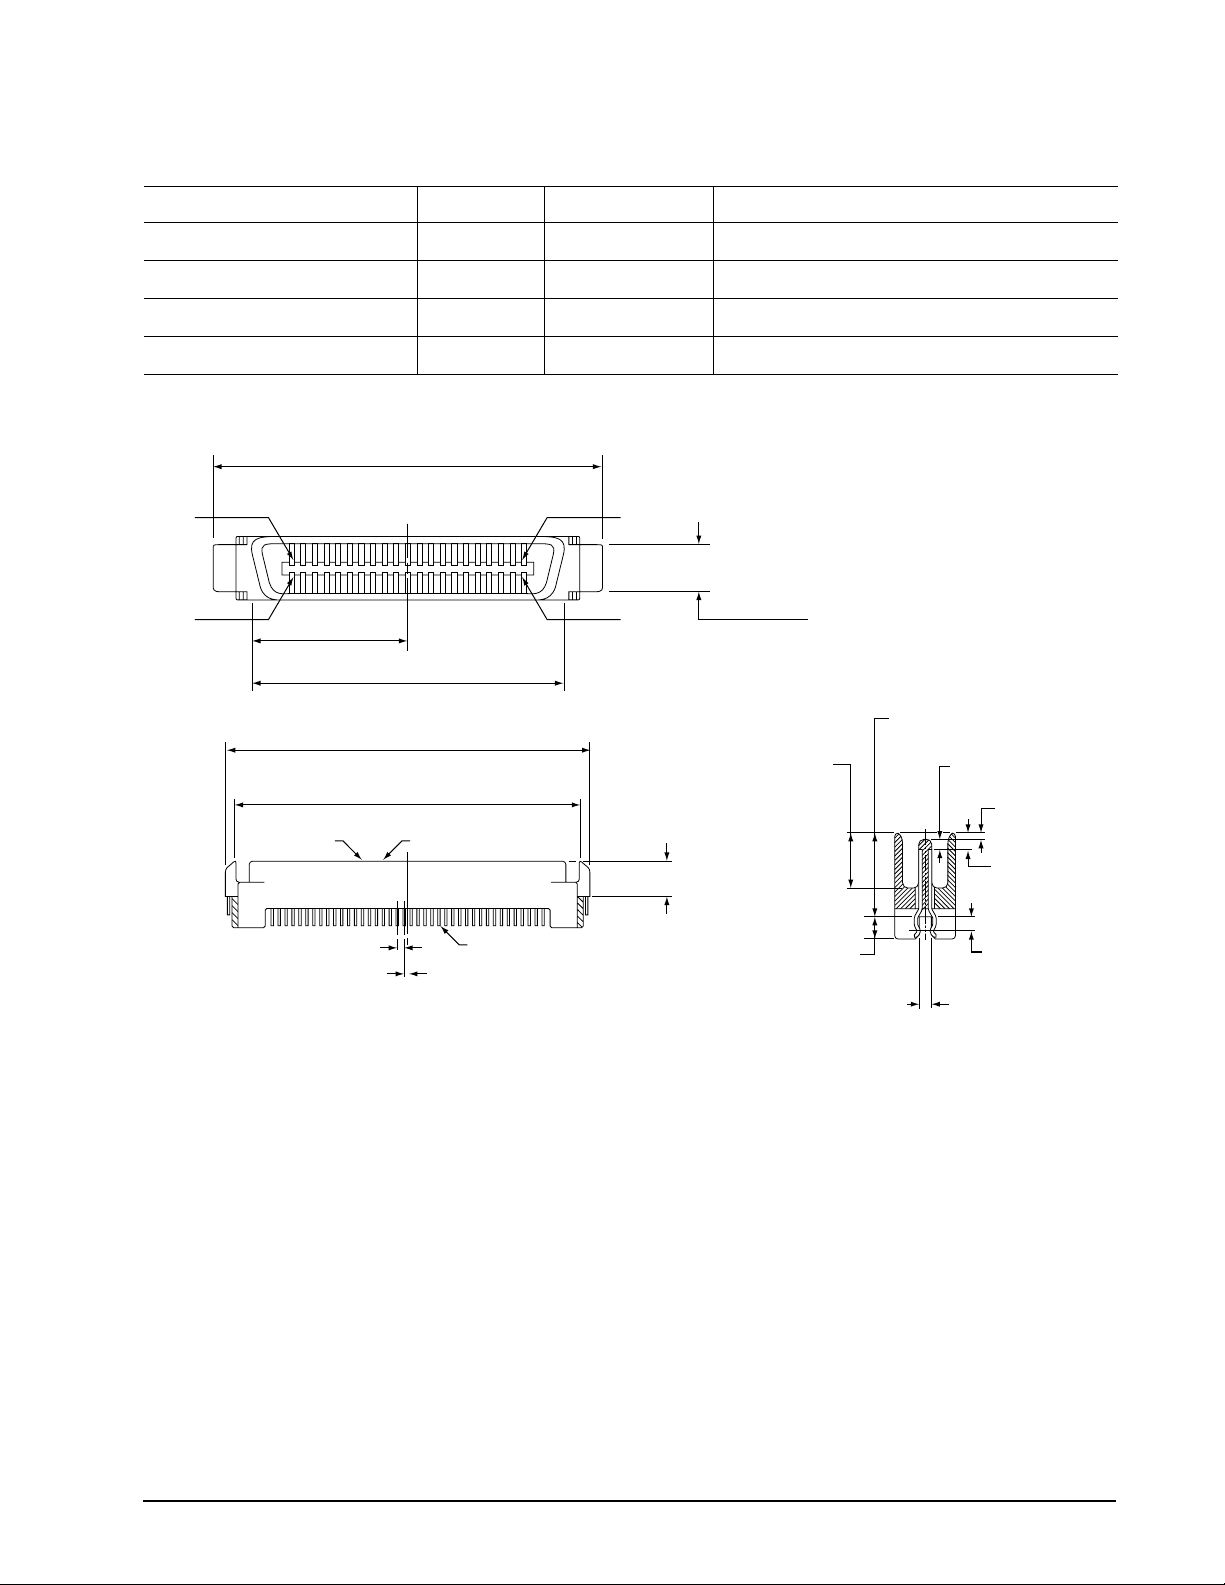
NL35 Series FC Product Manual, Rev. D
61
9.5.2 Connector requirements
P
P
s
(1.30 ± 0.16 mm)
Recommended mating SCA part number:
Part description Positions Part number Features
AMP Vertical (SCA sequence) 40 787317-1
Berg 40 71781
Methode 40 512-220-91-101N
Molex 40 717431040
The FC-AL SCA device connector is illustrated in Figure 10.
1.618 ± .003 in
(41.1 ± 0.08 mm)
in 20
in 40
.64 in
(16.24 mm)
1.28 in
(32.47 mm)
1.618 ± .003 in
(41.10 ± 0.08 mm)
1.492 ± .009 in
(37.90 ± 0.24 mm)
Mating end Housing
Pin 1
Pin 21
0.264+.007 in
–.010 in
(6.71+0.18 mm)
(–0.25 mm)
With polarization
With polarization
With polarization
With polarization
0.197 ± .003 in
(5.00 ± .08 mm)
0.226 in
(6.50 mm)
2 places
min.
0.394 ± .004 in
(10.0 ± 0.10 mm)
0.039 in
(0.75 mm)
min.
0.024 in
(0.60 mm)
0.079 ± .010 in
(2.00 ± .25 mm)
min.
(initial point
of contact)
.05 in
(1.27 mm)
Figure 10 . FC-AL SC A de v ice connect or dimensions
typ.
Contact (typ.)
.025 in (0.635 mm)
0.106 ± .010 in
(2.70 ± 0.25 mm)
0.060 ± .010 in
(1.52 ± 0.25 mm)
0.051 ± .006 in
2 place
9.5.3 Electrical description
Fibre Channel drives use the FC-SCA connector for:
• DC power
• FC-AL interface
• Drive select (device identification)
• Option selection
• Enclosure Services interface
This 40-pin connector is designed to plug directly into a backpanel. External cables are not required.
Page 70
62
NL35 Series FC Product Manual, Rev. D
9.5.4 Pin descriptions
This section provides a pin-out of the FC-SCA and a description of the functions provided by the pins.
T a bl e 29: FC-SCA pin desc ri ptio ns
Pin Signal name Signal type Pin Signal name Signal type
1* -EN bypass port A Low Voltage
2* 12 Volt s 22 Ground
3* 12 Volt s 23 Ground
4* 12 Volts 24* +Port A_in Diff. PECL input pair
5* -Parallel ESI 25* -Port A_in
6* Ground
7* Active LED out Open collector out 27* +Port B_in Diff. PECL input pair
8* Reserved 28* -Port B_in
9* Start_1 [2] TTL input 29 Ground
10* Start_2 [2] TTL input 30* +Port A_out Diff PECL output pair
11* -EN bypass port B Low Voltage
12* SEL_6 TTL input/output 32 Ground
13* SEL_5 TTL input/output 33* +Port B_out Diff PECL output pair
14* SEL_4 TTL input 34* -Port B_out
15* SEL_3 TTL input/output 35 Ground
16* Fault LED out Open collector out 36 SEL_2 TTL input/output
[1]
TTL output
TTL output
21 12 Volts charge
26 Ground
31* -Port A_out
17* DEV_CTRL_CODE_2
[2]
18* DEV_CTRL_CODE_1
[2]
19* 5 Volts 39 DEV_CTRL_CODE_0 [2] TTL input
20* 5 Volts 40 5 Volts charge
TTL input 37 SEL_1 TTL input/output
TTL input 38 SEL_0 TTL input/output
*Short pins in mating backpanel connector.
[1] This pin may be connected to external logic to detect the presence of the drive. The drive connects this
pin to the common ground.
[2] Pins 9, 10, 17 , 18, and 39 are opt io n sele ct pins and are tied high by the drive circuitry. The preferred elec-
trical connection at the backplane is either open or grounded (open for the ‘1’ setting, grounded for the ‘0’
setting). Alternativ ely, these pins may be driven by a 3.3V logic device, pull ed u p to 3.3V thro ugh a pu l l-up
resistor (recommended size of 10K ohm), or grounded through some other means.
Page 71
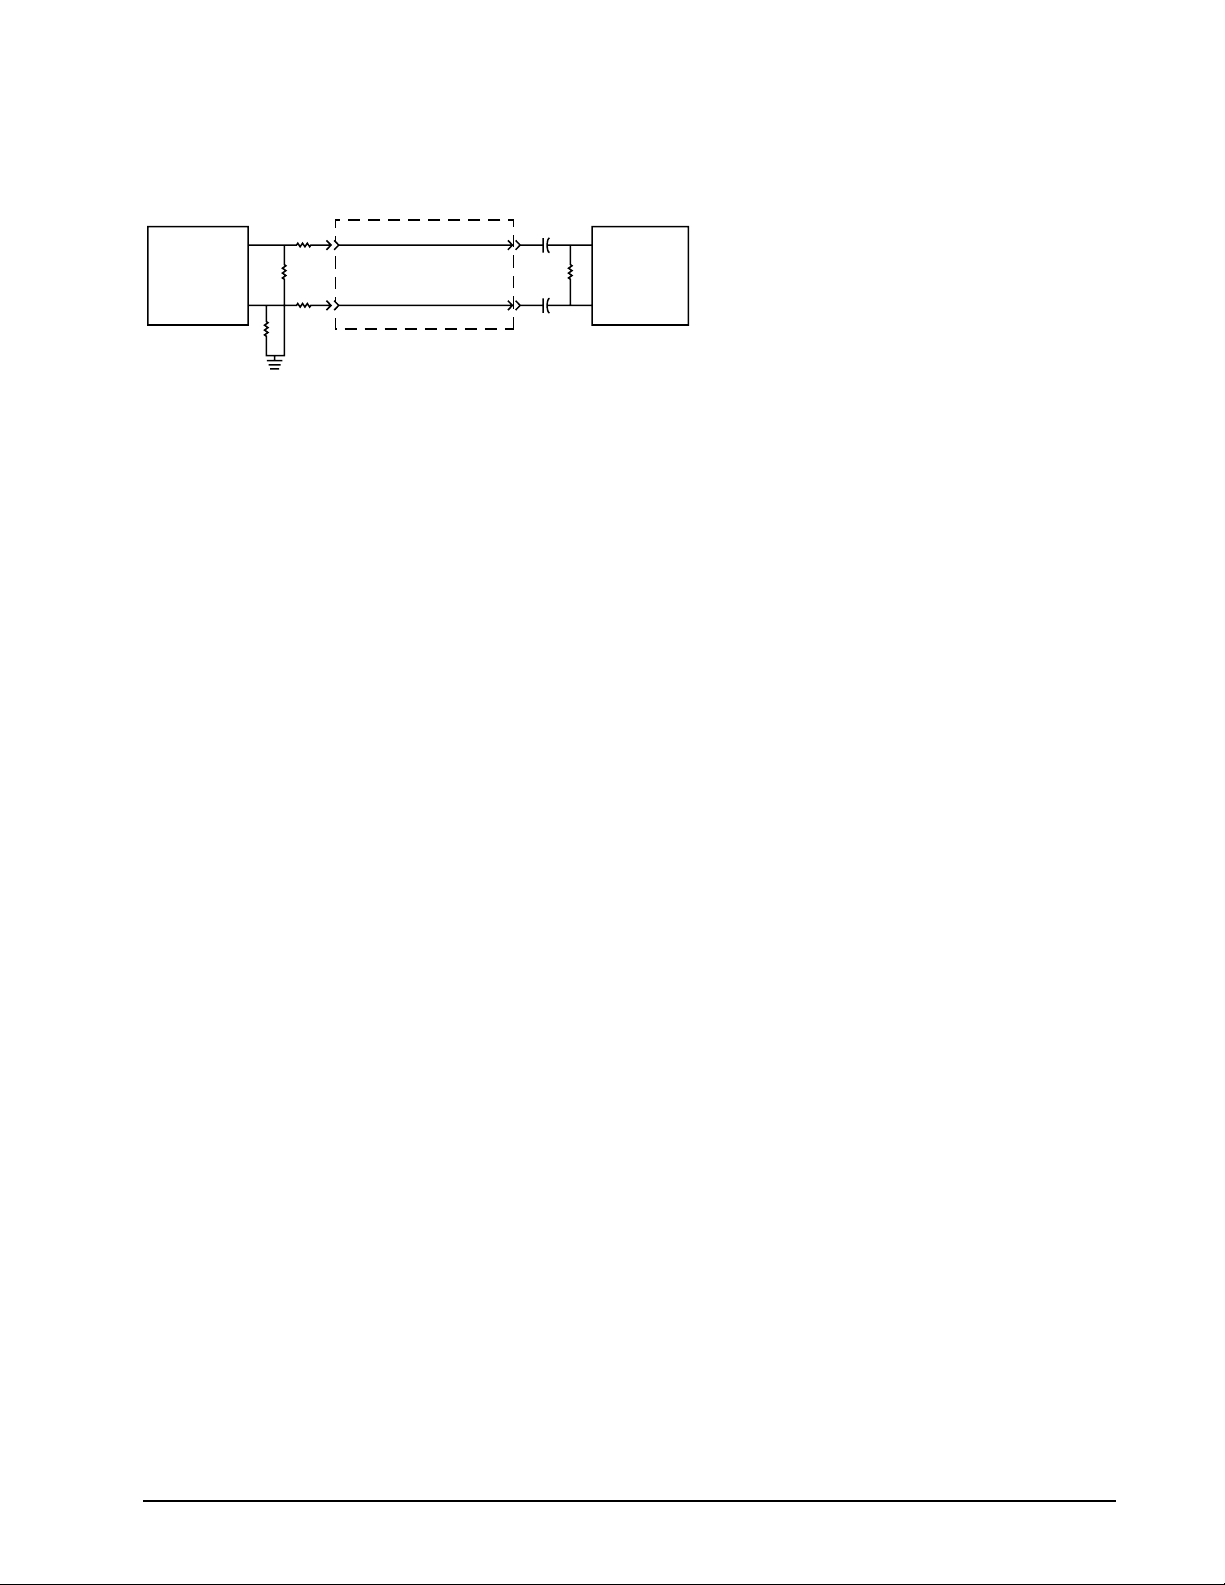
NL35 Series FC Product Manual, Rev. D
63
9.5.5 FC-AL transmitters and receivers
A typical FC-AL differential copper transmitter and receiver pair is shown in Figure 11. The receiver is required
to provide the AC coupling to eliminate ground shift noise.
68
TX
Transmitter
TY
150
Figure 11. FC-AL transmitters and receivers
150
68
Differential
Transfer Medium
.01
150
.01
RX
Receiver
RY
9.5.6 Power
Power is supplied through the FC-SCA with support for +5 volts and +12 volts. All of the voltage pins in the
drive connector are the same length.
Four 12 volt pins provide +12 volt power to the drive. The current return for the +12 volt power supply is
through the common ground pins. The supply current and return current must be distributed as evenly as possible among the pins. The maximum current typically occurs while the drive motor is starting.
Three 5 volt pins pro vide l ogic powe r to the d riv e. Th e curr ent re turn for the +5 vol t p ower sup pl y is th roug h the
common ground pins. Distribute supply and return current as evenly as possible among the voltage and
ground pins.
The mating connector pins use shorter contacts to achieve power surge reductions and to aid in “hot plugging”
the drives. There are longer voltage contacts in the connector to enable the drive filter capacitors to charge.
Current to the drive through the long charge pins is limited by the system in which the drive operates. Three of
the +12 volt pins ar e shor ter to all ow ca pa citi ve pr e-cha rging throu gh th e longe r + 12 v olt charge pi n . Two of the
+5 volt pins are shorter to allow capacitive precharging through the longer +5 volt charge pin.
9.5.7 Fault LED Out
The Fault LED Out signal is driven by the drive when:
• the drive detects failure of both ports
• the drive detects an internal failure
• the drive receives the appropriate fault LED command from the host
The Fault LED Out signal is designed to pull down the cathode of an LED. The anode is attached to the proper
+5 volt supply through an appropriate current-limiting resistor. The LED and the current-limiting resistor are
external to the drive.
Page 72
64
NL35 Series FC Product Manual, Rev. D
9.5.8 Active LED Out
The Active LED Out signal is driven by the drive as indicated in Table 30.
T a ble 30: Active LED Out condition s
Normal command activity LED status
Spun down and no activity Slow blink (20% on and 80% off a 2 sec cycle)
Spun down and activity (command executing) On
Spun up and no activity On
Spun up and activity (command executing) Off
Spinning up or down Blinks steadily (50% on and 50% off)
Format in progress, each cylinder change Toggles on/off
The Active LED Out signal is designed to pull down the cathode of an LED. The anode is attached to the
proper +5 volt supply through an appropriate current limiting resistor. The LED and the current limiting resistor
are external to the drive.
9.5.9 Enable port bypass signals
The – Enable Bypass P ort A (– EN BYP P ort A) an d – En able By p ass Port B (– EN BYP Por t B) si gnals con trol
the port bypass circuits (PBC) located external to the disc drive. The PBC allows a loop to remain functional in
the event of a drive failure or removal. When these signals are active, low, the PBC bypasses the drive on the
associated port. When an Enable Bypass signal is active, the corresponding Port Bypass LED signal in connector J1 is driven low by the disc drive. A pull down resistor, 1K, located with the PBC should be used to
insure the bypass is enabled if the disc drive is not installed.
The Enable Bypass signal is active under failing conditions within the drive, on detection of the Loop Port
Bypass primitive se quen ce, or on r emo val of t he dr ive. In the b yp ass state the drive con tinues t o re ceiv e on the
inbound fibre. Enable Bypass may be deactivated by detection of a Loop Port Enable primitive sequence if the
drive has completed self-test and a hardware failure is not present.
Failure modes detected by the disc drive that will enable bypass include:
• Transmitter/receiver wrap test failure
• Loss of receive clock
• Loss of transmission clock
• Drive interface hardware error
Page 73
NL35 Series FC Product Manual, Rev. D
65
9.5.10 Motor start controls
The drive’s motor is started according to the Start_1 and Start_2 signals described in Table 31. The state of
these signals can be wired into the backplane socket or driven by logic on the backplane.
T a ble 31: Motor start control sign als
Case Start_2 Start_1 Motor spin function
1 Low Low Motor spins up at DC power on.
2 High Low Motor spins up only when SCSI Start command is received.
3 Low High Motor spins up after a delay of 12 seconds times the modulo 8 value of
4 High High The drive will not spin up.
the numeric SEL ID of the drive from DC power on.
9.5.11 SEL_6 through SEL_0 ID lines
The SEL_6 through SEL_0 ID lines determine drive address, and, optionally, for an Enclosure Services Interface. When the Parallel ESI line is hig h, the en closure backp anel must provide address info rma tion on th e SEL
line. Refer to table 32 for a mapping of SEL to FC-AL physical addresses (AL_PA). You can think of the SEL
lines as the equivalent of a backpanel logic plug. The drives does not provide pull up resistors on these lines.
The backpanel is required to provide high and low inputs to the SEL_ID lines per the specifications in table 34
on page 67.
Note. Table 32 gives AL_PA values for each SEL value. The first entry in the table is SEL_ID 00. The last
entry is SEL_ID 7D. SEL_ID 7E is AL_PA 00 which is not valid for an NL_Port, so is not included in
the table. Also, SEL_ID 7Fh does map to a valid AL_PA; however, this value signals the drive that
physical addresses are not being assigned using the SEL lines and that a “soft” address will be
determined by FC-AL loop initialization.
When the Parallel ESI line is low, the enclosure backpanel logic switches to ESI mode if supported. There are
two modes of ESI, seven bits of enclosure status and a bidirectional mode. ESI support and the mode are
determined by the drive using a discovery process. Refer to the Fibre Channel Interface Manual for a descrip-
tion of ESI operation.
9.5.1 1.1 Parallel Enclosure Services Interface (ESI)
The parallel ESI line is an output from the drive. This line provides the enclosure with an indication of the
present function of the SEL lines. A high level, the default state, indicates the drive requires address information on the SEL lines. A low level indicates the drive is attempting an ESI transfer. The enclosure may not support ESI on any or all drive locations. It may only suppo rt the address functi on . Support of ESI is discovered by
the drive. Refer to the Fibre Channel Interface Manual for a description of ESI operations.
Page 74
66
NL35 Series FC Product Manual, Rev. D
Table 32: Arbitrated loop physical address (AL_PA) values
AL_PA
(hex)
EF 00 00 A3 2B 43 4D 56 86
E8 01 01 9F 2C 44 4C 57 87
E4 02 02 9E 2D 45 4B 58 88
E2 03 03 9D 2E 46 4A 59 89
E1 04 04 9B 2F 47 49 5A 90
E0 05 05 98 30 48 47 5B 91
DC 06 06 97 31 49 46 5C 92
DA 07 07 90 32 50 45 5D 93
D9 08 08 8F 33 51 43 5E 94
D6 09 09 88 34 52 3c 5F 95
D5 0A 10 84 35 53 3A 60 96
D4 0B 11 82 36 54 39 61 97
D3 0C 12 81 37 55 36 62 98
D2 0D 13 80 38 56 35 63 99
D1 0E 14 7C 39 57 34 64 100
CE 0F 15 7A 3A 58 33 65 101
CD 10 16 79 3B 59 32 66 102
SEL ID
(hex)
Setting
(dec)
AL_PA
(hex)
SEL ID
(hex)
Setting
(dec)
AL_PA
(hex)
SEL ID
(hex)
Setting
(dec)
CC 11 17 76 3C 60 31 67 103
CB 12 18 75 3D 61 2E 68 104
CA 13 19 74 3E 62 2D 69 105
C9 14 20 73 3F 63 2C 6A 106
C7 15 21 72 40 64 2B 6B 107
C6 16 22 71 41 65 2A 6C 108
C5 17 23 6E 42 66 29 6D 109
C3 18 24 6D 43 67 27 6E 110
BC 19 25 6C 44 68 26 6F 111
BA 1A 26 6B 45 69 25 70 112
B9 1B 27 6A 46 70 23 71 113
B6 1C 28 69 47 71 1F 72 114
B5 1D 29 67 48 72 1E 73 115
B4 1E 30 66 49 73 1D 74 116
B3 1F 31 65 4A 74 1B 75 117
B2 20 32 63 4B 75 18 76 118
B1 21 33 5C 4C 76 17 77 119
AE 22 34 5A 4D 77 10 78 120
AD 23 35 59 4E 78 0F 79 121
AC 24 36 56 4F 79 08 7A 122
Page 75
NL35 Series FC Product Manual, Rev. D
67
9.5.12 Device control codes
The drive inputs a Device Control Code on the DEV_CTRL_CODE lines at power up to determine the link rate
on the Fibre Channel ports. Both ports run at the same rate. If the backpanel does not connect to these lines,
the drive has 10K ohm pull up resistors that default the device control code to 7 (1.0625 GHz). Table 33 lists
the supported codes.
Table 33: Device control code values
2 (pin 17) 1 (pin 18) 0 (pin 39) Definition
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0 Reserved for Power failure warning.
1 Reserved for auto negotiation of link rate.
0 Reserved.
1 Reserved.
0 Reserved.
1 Reserved.
0 2.125 GHz operation on both ports.
1 1.0625 GHz operation on both ports.
9.6 Signal characteristics
This section describes the electrical signal characteristics of the drive’s input and output signals. See Table 29
on page 62 for signal type and signal name information.
9.6.1 TTL input characteristics
Table 34 provides the TTL characteristics.
T a ble 34: TTL characteristics
State Voltage Current
Input high 1.9 < VIH < 5.5V IIH = ±500nA max.
Input low -0.5V < VIL < 0.9V IOL = ±500nA max.
Output high (-EN Bypass A, B) 2.4 < V
Output low (-EN Bypass A, B) VOL < 0.5V IOL < 3mA
Output high (-Parallel ESI) 2.4 < V
VOH > 0.9V
Output low (-Parallel ESI) 0 < VOL < .45V IOL < 2.4mA
Output high (all other outputs) 2.4 < V
VOH > 0.9V
Output low (all other outputs) 0 < VOL < .45V IOL < 1.6mA
< 5.25V IOH < -3mA
OH
< 0.9 V
OH
< 0.9 V
OH
CC
CC
CC
CC
IOH < -2.4mA
I
< -500µA
OH
IOH < -1.6mA
I
< -500µA
OH
Page 76
68
NL35 Series FC Product Manual, Rev. D
9.6.2 LED driver signals
Fault and Active LED signals are located in the FC-SCA conne ctor (J1) . See Table 35 for the output characteristics of the LED drive signals.
Table 35: LED drive signal
State Current drive available Output voltage
LED off, high 0 < IOH < 100µA
LED on, low IOL < -30 mA 0 < VOL < 0.8V
9.6.3 Differential PECL output
The serial PECL outp ut signa l vol t age c hara cteri stics a re p rovided i n Table 36. The outp ut s are not A C cou pled
in order to deliver maximum signal without rise and fall time degradation. You must AC couple the receiver to
isolate potentially different DC characteristics of the outputs and the receiver.
Table 36: Differential PECL output characteristics
Description Parameter
Serial output voltage swing 600 < V
< 1300 mV
out
Figure 12 provide s the data o utput valid eye diagram relative to the bit cell time. Table 38 lists the data values.
Bit Time
Vout (mv)
XMIT Eye
Figure 12. Transmit eye diagram
9.6.4 Differential PECL input
The serial PECL input signal voltage characteristics are provided in Table 37.
Table 37: Differential PECL input characteristics
Description Parameter Notes
Serial input voltage swing 400 < Vin < 2.000 mV AC coupled
Page 77
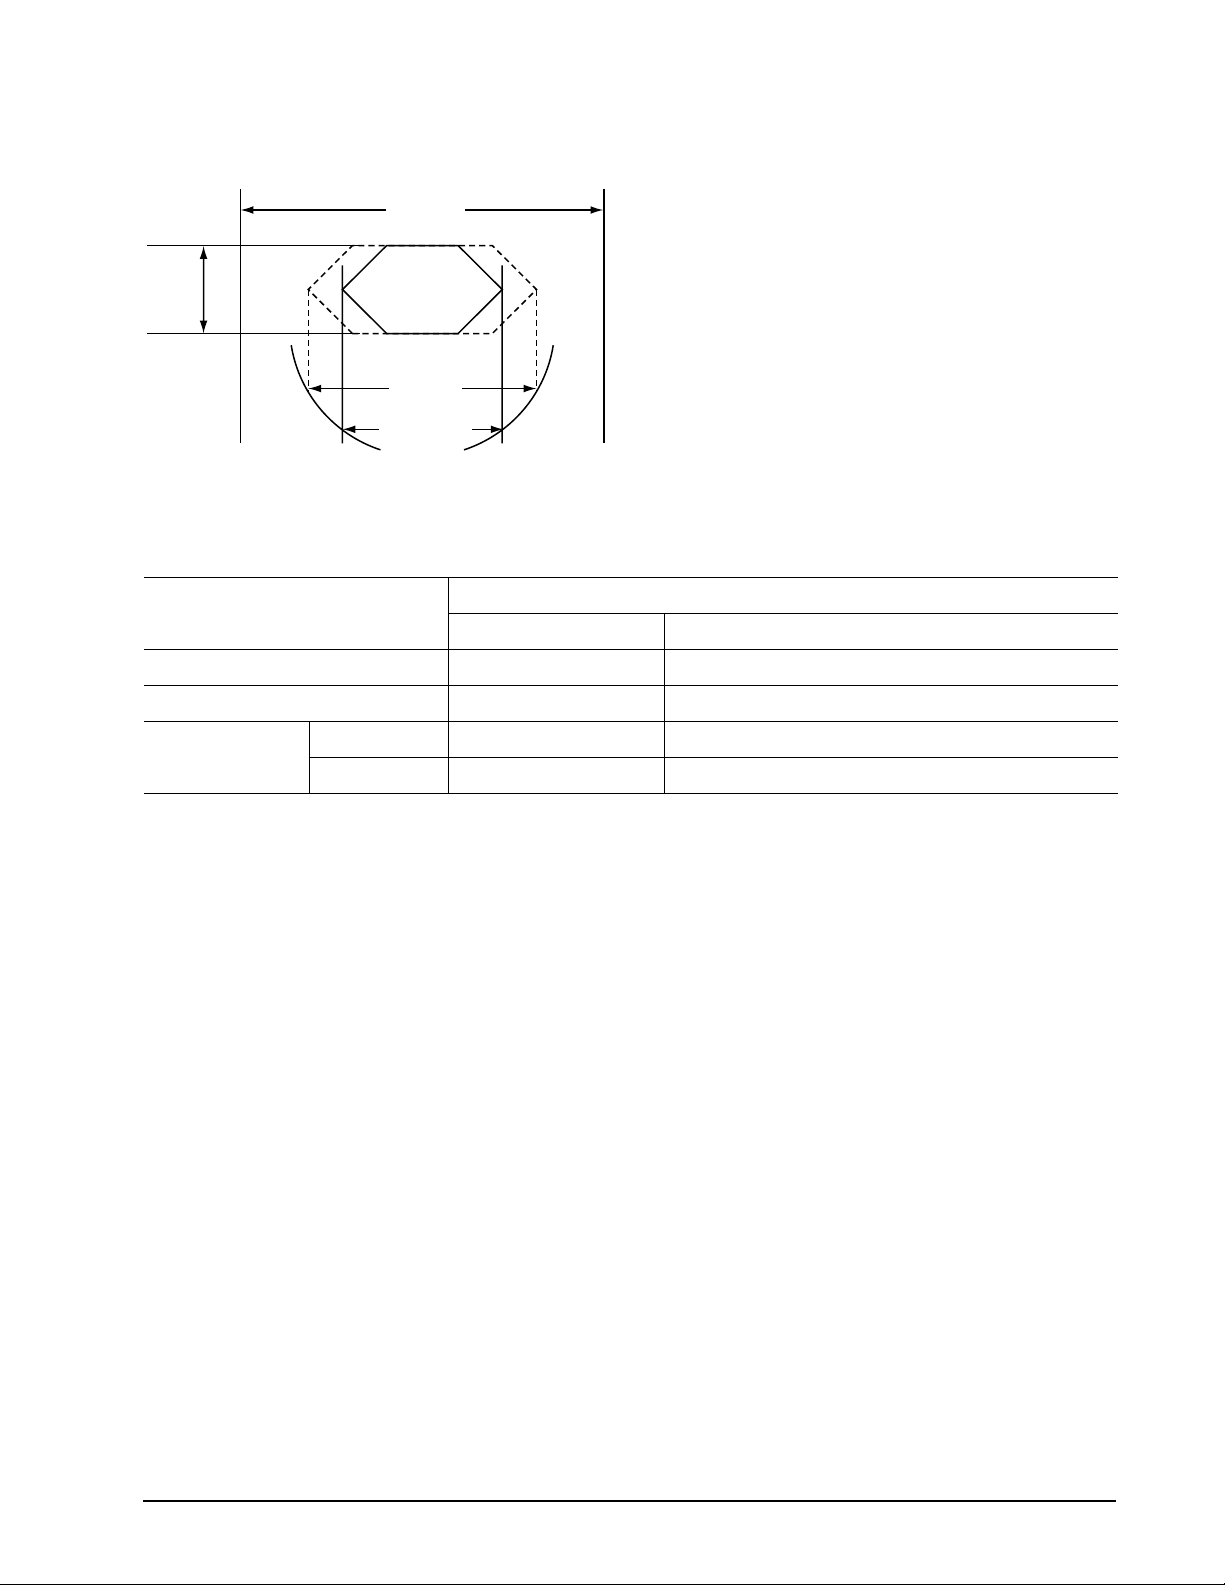
NL35 Series FC Product Manual, Rev. D
69
Figure 13 provides the data valid eye diagram for typical and minimum requirements to recover data at the
specified interface error rate. The inputs are AC coupled on the drive. Table 38 lists the data values.
Bit Time
Vin (mv)
RCV Eye
(typical)
(minimum)
Figure 13. Receive eye diagram
Table 38: Eye diagram data values
Link rate
1 GHz 2 GHz
Bit time 941 ps 470 ps
XMIT eye 725 ps min. 315 ps min.
RCV eye
Typical 659 ps 305 ps
Minimum 395 ps 226 ps
Page 78
70
NL35 Series FC Product Manual, Rev. D
Page 79
NL35 Series FC Product Manual, Rev. D
71
10.0 Seagate Technology support services
Internet
For information regarding Seagate products and services, visit www.seagate.com. Worldwide support is
available 24 hours daily by email for your questions.
Presales Support:
T e chn i cal Supp or t:
Warranty Support:
http://www.seagate.com/support/service/index.html
mySeagate
my.seagate.com is the industry's first Web portal designed specifically for OEMs and distributors. It provides
self-service access to critical applications, personalized content and the tools that allow our partners to
manage their Seagate account functions. Submit pricing requests, orders and returns through a single,
password-protected Web interface-anytime, anywhere in the world.
spp.seagate.com
spp.seagate.com supports Seagate resellers with product information, program benefits and sales tools. You
may register for customiz e d communi cation s that ar e not ava ila ble on the web. The s e communi catio ns cont ai n
product launch, EOL, pricing, promotions and other channel-related information. To learn more about the
benefits or to register, go to spp.seagate.com, any time, from anywhere in the world.
Seagate Service Centers
Presales Support
Our Presales Support staff can help you determine which Seagate products are best suited for your specific
application or computer system, as well as product availability and compatibility.
Technical Support
Seagate technical support is available to assist you online at support.seagate.com or through one of our call
centers. Have your system configuration information and your “ST” model number available.
SeaTDD™ (+1-405-324-3655) is a telecommunications device for the deaf (TDD). You can send questions or
comments 24 hours daily and exchange messages with a technical support specialist during normal business
hours for the call center in your region.
Page 80
72
NL35 Series FC Product Manual, Rev. D
Customer Service Operations
Warranty Service
Seagate offer s worldwi de custom er supp ort for Seagate pro duct s . Seagate distr i butors, OEM s and other direct
customers should contact their Seagate Customer Service Operations (CSO) representative for warrantyrelated issues. Resellers or end users of drive products should contact their place of purchase or Seagate
warranty service for assistance. Have your serial number and model or part number available.
Data Recove ry Service s
Seagate offers data recovery services for all formats and all brands of storage media. Our data recovery
services labs are currently located throughout the world. . Additional information, including an online request
form and data loss prevention resources, is available at http://services.seagate.com/index.aspx
Authorized Service Centers
Seagate Service Centers are available on a global basis for the return of defective products. Contact your
customer support representative for the location nearest you.
USA/Canada/Latin America support services
For an extensive list of telephone numbers to technical support, presales and warranty service in USA/
Canada/Latin America, including business hours, go to the "Contact Us" page on www.seagate.com.
Global Customer Support
Presales, Technical, and Warranty Support
Call Center Toll-free Direct dial
USA, Canada,
and Mexico 1-800-SEAGATE +1-405-324-4700
Data Recovery Services
Call Center Toll-free Direct dial FAX
USA, Canada, 1-800-475-01435 +1-905-474-2162 1-800-475-0158
and Mexico +1-905-474-2459
Europe, the Middle East and Africa Support Services
For an extensive list of telephone numbers to technical support, presales and warranty service in Europe, the
Middle East and Africa, go to the "Contact Us" page on www.seagate.com.
Asia/Pacific Support Services
For an extensive list of telephone numbers to technical support, presales and warranty service in Asia/Pacific,
go to the "Contact Us" page on www.seagate.com.
Page 81
NL35 Series FC Product Manual, Rev. D
73
Index
Numerics
12 volt
pins 63
3rd party reserve command 54
5 volt pins 63
BB-Credit 45, 48
buffer
data 8
space 13
busy status 59
bypass circuit 19
Byte check command 52
bytes per surface 11
bytes per track 11
A
Abort Sequence (ABTS) 43
abort task set function 44
AC coupling 63
AC power requirements 25
ACA active status 59
ACA active, faulted initiator status 59
Accept (ACC) 43
access time 11
acoustics 32
active LED Out signal 64
Actual retry count bytes command 50
actuator 9
assembly design 7
adaptive caching 59
Address Discovery (ADISC) 43
addresses 60
air cleanliness 31
air flow 40
illustrated 40
Alternate credit model 45, 48
altitude 28
ambient 28
ANSI documents
fibre channel 5
SCSI 5
arbitrated loop physical address (AL_PA) 39
arbitration 39
asynchronous event notification 59
audible noise 3
Australia/New Zealand Standard 4
auto write and read reallocation
programmable 8
automatic contingent allegiance 59
automatic shipping lock 7
average idle current 25
average rotational latency 11
B
backpanel 61
backplane 65
basic link service frames 43
Basic_Accept (BA_ACC) 43
Basic_Reject (BA_RJT) 43
BB 45, 48
C
cache operation 13
cache segments 14
Caching parameters page (08h) command 51
caching write data 14
Canadian Department of Communications 3
capacity
unformatted 11
capacity, drive, programmable 10
CF 45, 48
Change definition command 53
character sync 19
charge pins 63
check condition status 59
Class 3 parameters 45, 48
class B limit 3
Class valid 45, 48
clear ACA function 44
clear task set function 44
command descriptor block (CDB) 12
commands supported 50
Common features 45, 48
Compare command 52
Concurrent sequences 45
condensation 28
condition met/good status 59
connect/disconnect 12
connector
illustrated 61
requirements 61
continuous vibration 31
Continuously increasing offset 45, 48
Control mode page (0Ah) command 51
controller overhead 11
cooling 40
Copy and verify command 52
Copy command 50
CRC 19
error 18
CS 45
customer service 24
D
data block size
Page 82
74
NL35 Series FC Product Manual, Rev. D
modifing the 9
data heads
read/write 11
data rate
internal 11
data transfer rate 12
data valid eye 69
Date code page command 50
DC power 61
requirements 25
dedicated landing zone 7
defect and error management 35
deferred error handling 59
description 7
DEV_CTRL_CODE 67
device behavior page command 50
device control code values 67
device control codes 67
device identification page command 50
device selection IDs 39
devices 39
differential PECL input 68
dimensions 33
Disable page out command 51, 52
disc media 12
disc rotation speed 11
Disconnect/reconnect control (page 02h) command
51
Download microcode and save modes (5) 52
Download microcode mode (4) 52
Download microcode with offsets and save mode (7)
52
Download microcode with offsets mode (6) 52
drive 31
drive capacity
programmable 10
drive characteristics 11
drive failure 19
drive ID 39
drive ID/option select headers 39
drive malfunction 19
drive mounting 33, 41
drive orientation 39
drive select 61
driver signals 68
drivers and receivers 8
dual port support 49
E
electrical
description of connector 61
signal characteristics 67
specifications 25
electromagnetic compatibility 3
electromagnetic susceptibility 32
EMI requirements 3
enable bypass
port A 64
port B 64
signal 64
state 19
Enclosure Services interface 61
Enclosure services page command 51
environmental
limits 28
requirements 17
environmental contro l 31
error
detection mechanisms, FC 19
management 35
rates 17
error correction code
96-bit Reed-Solomon 8
Error recovery page (01h) command 51
execution time 12
extended link service
frames 43
reply frames 43
Extended sense command 50
Extent reservation command 54
F
fabric 48
Fabric Address Notification (FAN) 43
Fabric Login (FLOGI) 43
FAN 48
fault LED out signal 63
FC-AL
document 5
interface 39, 61
options supported 49
physical interface 60
SCA device connector, illustrated 61
selective reset 59
FCC rules and regulations 3
FCP
for SCSI, document 5
response codes 44
task management functions 44
FC-PH document 5
features 8
interface 43
Fibre Channel documents 5
Fibre Channel interface control page 51
Fibre Channel Interface Manual 1, 5
Fibre Channel Services 43
Field pointer bytes command 50
firmware 8
corruption 54
Firmware download option command 52
Page 83
NL35 Series FC Product Manual, Rev. D
75
Firmware numbers page command 50
flawed sector reallocation 8
FLOGI
received on Port A 47
received on Port B 47
Force unit access command 51
form factor 8
format 39
Format command execution time 11
Format page (03h) command 51
Format unit command 50
front panel 33
FS 45, 46, 48
function
complete, code 00 44
not supported, code 05 44
reject, code 04 44
G
Good status 59
gradient 28
ground shift noise 63
grounding 41
H
hard assigned arbitrated loop physical address
(AL_PA) 39
HDA 41
heads
read/write data 11
heat removal 40
host equipment 41
hot plugging the drive 19
humidity 28
humidity limits 28
I
IC 45
ID and configuration options 8
Implemented operating def. page command 50
Information exceptions control page (1Ch) command
51
Initiator control 45
Inquiry command 50
inquiry data 55
installation 39
guide 5
interface 39
commands supported 50
description 60
error rate 17
errors 18
illustrated 60
physical 60
requirements 43
interleave 8
intermediate/condition met/good status 59
intermediate/good status 59
Intermix 45, 48
internal data rate 11
internal defects/errors 35
internal drive characteristics 11
J
J1 connector 39
Jumper settings page command 50
jumpers 39
L
latency
average rotational 11, 12
LBdata 53
LED driver signals 68
link rate 67
Link Service Reject (LS_RJT) 43
link services supported 43
Lock-unlock-cache command 52
Log select command 53
Log sense command 53
logic power 63
logical block address 13
logical block reallocation scheme 8
logical block size 8, 12
logical segments 13
Logout (LOGO) 43
loop 60, 64
disruption 19
initialization 39
loop position
FC-AL options 49
loop position report
FC-AL options 49
LS_RJT 45, 48
LSI circuitry 9
M
maintenance 17
maximum delayed motor start 25
maximum start current 25
Mean Time Between Failure 19
media description 9
miscellaneous feature support
Adaptive caching 59
Asynchronous event notification 59
Automatic contingent allegiance 59
Deferred error handling 59
FC-AL selective reset 59
Parameter rounding 59
Page 84
76
NL35 Series FC Product Manual, Rev. D
Queue tagging 59
Reporting actual retry count 59
Segmented caching 59
SMP = 1 in Mode Select command 59
Synchronized (locked) spindle operation 59
Zero latency read 59
miscellaneous status support
ACA active 59
ACA active, faulted initiator 59
Busy 59
Check condition 59
Condition met/good 59
Good 59
Intermediate/condition met/good 59
Intermediate/good 59
Reservation conflict 59
Task set full 59
miscorrected media data 17
Mode select
(10) command 54
command 50
Mode sense
(10) command 54
command 51
data, table 55, 57, 58
monitoring state 19
motor start
controls 65
option 13
mounting 41
holes 41
orientations 39
mounting configuration 33
mounting configuration dimensions 33
MTBF 19
N
N_Port Login (PLOGI) 43
payload 45
payload values 46
NN 45, 48
Node Name 48
Node name 45
noise
audible 3
noise immunity 26
non-operating 28, 29, 31
temperature 28
non-operating vibration 31
O
office environment 31
old port state
FC-AL options 49
OPEN Full Duplex
FC-AL options 49
OPEN half duplex
FC-AL options 49
Open sequences per exchange 45
operating 28, 29, 31
operating environment 19
option configurations 39
option selection 61
options 10, 49
orientation 12
OS 45
out-of-plane distortion 41
overhead time
for head switch 12
for one track cylinder switch 12
P
P_LOGI
received on Port A 46
received on Port B 46
package size 29
package test specification 5
packaged 29
parameter rounding 59
pass-through state 19
PBC 60, 64
PBdata 53
PCBA 41
peak bits per inch 11
peak operating current 25
PECL input 68
performance characteristics
detailed 11
performance degradation 29
performance highlights 9
physical damage 31
physical interface 60
description 60
physical specifications 25
PI 46, 47
pin descriptions 62
PN 45, 48
port bypass circuit 19, 60, 64
Port DISCovery 45
Port Discovery (PDISC) 43
port identifier field 46, 47
port login 45
accept 46
Port Name 48
Port name (initiator’s) 45
power 63
dissipation 27
requirements, AC 25
requirements, DC 25
Page 85
NL35 Series FC Product Manual, Rev. D
77
sequencing 26
power connector 26
Power control page (1Ah) command 51
power distribution 3
power-on operating hours 19
power-up hours 19
Prefetch command 52
prefetch/multi-segme nted cache control 13
preventive maintenance 17
private loop
FC-AL options 49
Proc Assc 45
Process Accept (ACC) 47
Process Login (PRLI) 43, 46
Process Login Accept (ACC) payload 47
process login payload data 46
Process Logout (PRLO) 43
programmable drive capacity 10
public loop
FC-AL options 49
pull down resistor 64
Register FC-4 Types (RFT_ID) 43
Relative address command 51, 52
relative humidity 28
Release command 50
Released (10) command 54
reliability 9
specifications 17
reliability and service 18
repair and return information 24
reporting actual retry count 59
Request sense command 50
reservation conflict status 59
Reserve command 50
Reserved (10) command 54
resonance 29
return information 24
Rezero unit command 50
Rigid disc drive geometry page
command 51
rotation speed 11
running disparity 19
Q
queue tagging 59
R
radio interference regulations 3
Random relative offset 45, 48
RCD bit 13
Read buffer command 53
Read capacity command 51
Read combined header and data mode (0) 53
Read command 50
Read data mode (2) 53
Read defect data command 52
Read descriptor mode (3) 53
read error rates 17
Read extended command 51
Read Link Status (RLS) 43
Read long command 53
read/write data heads 11
Reassign blocks command 50
Receive buffer field size 45, 48
receive buffer field size 46
Receive diagnostic results command 51
receive eye
diagram 69
receivers 63
recommended mounting 30
Recoverable Errors 18
recovered media data 17
reference
documents 5
Regenerate command 54
S
safety 3
SCA part numbers 61
SCSI interface
commands supported 50
SCSI Interface Product Manual 3
Search data
equal command 52
high command 52
low command 52
sector interleave 12
Seek command 50
seek error
defined 18
rate 17
Seek extended command 52
seek performance characteristics 11
segmented caching 59
SEL ID 39
lines 65
standard feature 8
Self-Monitoring Analysis and Reporting Technology
9, 20
Send diagnostics page command 51
Sequential delivery 45, 48
service
life 17
Service Options 48
Service options 45
Set limits command 52
shielding 3
shipping 24
shipping container 28
Page 86
78
NL35 Series FC Product Manual, Rev. D
shock 29
and vibration 29
shock mount 41
signal
characteristics 67
LED driver 68
single-unit shipping pack kit 10
SMART 9, 20
SMP = 1 in Mode Select command 59
SO 45, 48
spindle brake 8
Stacked connection req. 45, 48
standards 3
Start unit/stop unit command 51
start/stop time 13
support services 71
Supported diagnostics pages command 51
surface stiffness
allowable for non-flat surface 41
switches 39
Synchronize cache command 52
synchronized spindle
operation 59
system chassis 41
T
target reset function 44
task management functions 44
Abort task set 44
Clear ACA 44
Clear task set 44
Target reset 44
terminate task 44
task management response codes 44
Function complete 00 44
Function not supported 05 44
Function reject 04 44
task set full status 59
technical support services 71
temperature 12, 21, 28, 40
limits 28
non-operating 28
regulation 3
See also cooling
temperature sensor 21
terminate task function 44
terminators 39
Test unit ready command 50
thermal monitor 21
Third-party Process Logout (TRPLO) 43
tracks per inch 11
tracks per surface 11
Translate page command 51
transmit eye diagram 68
transmitters 63
transporting the drive 24
TTL input characteristics 67
typical access time 12
U
UI 46, 47
unformatted 9
unique identifier 46, 47
Unit attention page (00h) command 51
Unit serial number page command 50
Unrecoverable Errors 18
unrecovered media data 17
V
Valid version level 45, 48
Verify command 52
Verify error recovery page (07h) command 51
vibration 29, 31
Vital product data page command 50
voltage 12
W
warranty 24
word sync 19
Write and verify command 52
Write buffer command 52
Write combined header and data mode (0) 52
Write command 50
Write data mode (2) 52
Write extended command 51
Write long command 53
Write same command 53
X
XD read 53
XD write 53
XD write extended command 54
XID reassign 45
XP write 53
Z
zero latency read 59
zone bit recording (ZBR) 8
Page 87
Page 88
Seagate Technology LLC
920 Disc Drive, Scotts Valley, California 95066-4544, USA
Publication Number: 100343673, Rev. D, Printed in USA
 Loading...