

Page 1
Product Manual
Cheetah 15K.7 SAS
Standard models
ST3600057SS
ST3450857SS
ST3300657SS
Self-Encrypting Drive models
ST3600957SS
ST3450757SS
ST3300557SS
SED FIPS 140-2 models
ST3600857SS
ST3450657SS
ST3300457SS
100516226
Rev. D
November 2010
Page 2
© 2010, Seagate Technology LLC All rights reserved.
Publication number: 100516226, Rev. D November 2010
Seagate, Seagate Technology and the Wave logo are registered trademarks of Seagate Technology
LLC in the United States and/or other countries. Cheetah and SeaTools are either trademarks or
registered trademarks of Seagate Technology LLC or one of its affiliated companies in the United
States and/or other countries. The FIPS logo is a certification mark of NIST, which does not imply
product endorsement by NIST, the U.S., or Canadian governments. All other trademarks or
registered trademarks are the property of their respective owners.
No part of this publication may be reproduced in any form without written permission of Seagate
Technology LLC. Call 877-PUB-TEK1 (877-782-8351) to request permission.
One gigabyte, or GB, equals one billion bytes and one terabyte, or TB, equals one trillion bytes.
Your computer's operating system may use a different standard of measurement and report a lower
capacity. In addition, some of the listed capacity is used for formatting and other functions, and thus
will not be available for data storage. Seagate reserves the right to change, without notice, product
offerings or specifications.
Page 3
Contents
1.0 Seagate Technology support services. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 1
2.0 Scope. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 2
3.0 Standards, compliance and reference documents . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 3
3.1 Standards . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 3
3.1.1 Electromagnetic compatibility. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 3
3.2 Compliance . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 4
3.2.1 Electromagnetic compliance . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 4
3.3 European Union Restriction of Hazardous Substances (RoHS) . . . . . . . . . . . . . . . . . . . . . 4
3.4 Reference documents . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 5
4.0 General description . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 6
4.1 Standard features . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 7
4.2 Media description . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 7
4.3 Performance . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 7
4.4 Reliability . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
4.5 Formatted capacities . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
4.6 Programmable drive capacity . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
4.7 Factory-installed options . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
5.0 Performance characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
5.1 Internal drive characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
5.2 Seek time. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
5.2.1 Access time . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
5.2.2 Format command execution time (minutes). . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
5.2.3 General performance characteristics. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
5.3 Start/stop time . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
5.4 Prefetch/multi-segmented cache control . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
5.5 Cache operation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
5.5.1 Caching write data . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 12
5.5.2 Prefetch operation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 12
6.0 Reliability specifications . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
6.1 Error rates . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
6.1.1 Recoverable Errors . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
6.1.2 Unrecoverable Errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
6.1.3 Seek errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
6.1.4 Interface errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
6.2 Reliability and service . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
6.2.1 Annualized Failrue Rate (AFR) and Mean time between failure (MTBF). . . . . . 14
6.2.2 Preventive maintenance. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
6.2.3 Hot plugging the drive . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
6.2.4 S.M.A.R.T. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 15
6.2.5 Thermal monitor. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 16
6.2.6 Drive Self Test (DST). . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 17
6.2.7 Product warranty . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 19
7.0 Physical/electrical specifications . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 20
7.1 AC power requirements. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 20
7.2 DC power requirements. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 20
7.2.1 Conducted noise immunity. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 24
7.2.2 Power sequencing . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 24
7.2.3 Current profiles. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 24
7.3 Power dissipation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 27
7.4 Environmental limits . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 29
Cheetah 15K.7 SAS Product Manual, Rev. D i
Page 4
7.4.1 Temperature. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 29
7.4.2 Relative humidity . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 30
7.4.3 Effective altitude (sea level) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 30
7.4.4 Shock and vibration . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 30
7.4.5 Acoustics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 33
7.4.6 Air cleanliness . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 33
7.4.7 Corrosive environment . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 33
7.4.8 RoHS compliance statement . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 33
7.4.9 Electromagnetic susceptibility . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 34
7.5 Mechanical specifications . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 34
8.0 About FIPS. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 35
9.0 About self-encrypting drives . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 36
9.1 Data encryption . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 36
9.2 Controlled access. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 36
9.2.1 Admin SP . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 36
9.2.2 Locking SP . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 36
9.2.3 Default password . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
9.3 Random number generator (RNG). . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
9.4 Drive locking. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
9.5 Data bands. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
9.6 Cryptographic erase. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
9.7 Authenticated firmware download . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
9.8 Power requirements. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 38
9.9 Supported commands . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 38
10.0 Defect and error management. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 39
10.1 Drive internal defects/errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 39
10.2 Drive error recovery procedures . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 39
10.3 SAS system errors. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 41
10.4 Background Media Scan . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 41
10.5 Media Pre-Scan . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 42
10.6 Deferred Auto-Reallocation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 42
10.7 Idle Read After Write . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 42
11.0 Installation. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 43
11.1 Drive orientation. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 43
11.2 Cooling. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 43
11.3 Drive mounting. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 44
11.4 Grounding . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 44
12.0 Interface requirements . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 45
12.1 SAS features . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 45
12.1.1 task management functions. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 45
12.1.2 task management responses . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 45
12.2 Dual port support . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 46
12.3 SCSI commands supported. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 46
12.3.1 Inquiry data. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 50
12.3.2 Mode Sense data . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 51
12.4 Miscellaneous operating features and conditions . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 57
12.4.1 SAS physical interface . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 58
12.4.2 Physical characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 60
12.4.3 Connector requirements. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 60
12.4.4 Electrical description. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 61
12.4.5 Pin descriptions . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 61
12.4.6 SAS transmitters and receivers . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 62
ii Cheetah 15K.7 SAS Product Manual, Rev. D
Page 5
12.4.7 Power. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 62
12.5 Signal characteristics. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 62
12.5.1 Ready LED Out . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 62
12.5.2 Differential signals . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 63
12.6 SAS-2 Specification compliance . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 63
12.7 Additional information . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 63
Cheetah 15K.7 SAS Product Manual, Rev. D iii
Page 6
iv Cheetah 15K.7 SAS Product Manual, Rev. D
Page 7
1.0 Seagate Technology support services
SEAGATE ONLINE SUPPORT and SERVICES
For information regarding products and services, visit http://www.seagate.com/www/en-us/about/contact_us/
Available services include:
Presales & Technical support
Global Support Services telephone numbers & business hours
Authorized Service Centers
For information regarding Warranty Support, visit
http://www.sea
For information regarding Data Recovery Services, visit http://www.i365.com
For Seagate OEM & Distribution partner portal, visit https://direct.seagate.com/portal/system
For Seagate reseller portal, visit http://spp.seagate.com
gate.com/www/en-us/support/warranty_&_returns_assistance
Cheetah 15K.7 SAS Product Manual, Rev. D 1
Page 8
2.0 Scope
This manual describes Seagate Technology® LLC, Cheetah® SAS (Serial Attached SCSI) disk drives.
Cheetah 15K.7 drives support the SAS Protocol specifications to the extent described in this manual. The SAS
Interface Manual (part number 100293071) describes the general SAS characteristics of Cheetah 15K.7 and
other Seagate SAS drives. The Self-Encrypting Drive (SED) Users Guide, part number 100515636 describes
the interface, general operation and security features available on SED drives.
Note. Previous generations of Seagate Self-Encrypting Drive models were called Full Disk Encryption
(FDE) models before a differentiation between drive-based encryption and other forms of encryp
tion was necessary.
Model Number Capacity Self-Encrypting Drive (SED) FIPS 140-2 Level 2 certified
ST3600057SS
ST3600957SS Yes No
ST3600857SS Yes Yes
ST3450857SS
ST3450757SS Yes No
ST3300457SS Yes Yes
ST3300657SS
ST3300557SS Yes No
ST3300457SS Yes Yes
600GB
450GB
300GB
No No
No No
No No
-
For more information on FIPS 140-2 Level 2 certification see Section 8.0 on page 35.
2 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 9
3.0 Standards, compliance and reference documents
The drive has been developed as a system peripheral to the highest standards of design and construction. The
drive depends on its host equipment to provide adequate power and environment for optimum performance
and compliance with applicable industry and governmental regulations. Special attention must be given in the
areas of safety, power distribution, shielding, audible noise control, and temperature regulation. In particular,
the drive must be securely mounted to guar antee the specified performance characteristics. Mounting by bottom holes must meet the requirements of Section 11.3.
3.1 Standards
The Cheetah 15K.7 SAS family complies with Seagate standards as noted in the appropriate sections of th is
manual and the Seagate SAS Interface Manual, part number 100293071.
The drives are recognized in accordance with UL 60950-1 and CSA 60950-1 as tested by UL and EN60950-1
as tested by TUV.
The security features of Cheetah 15K.7 SAS SED models are based on the “TCG Storage Architecture Core
Specification” and the “TCG Storage Workgroup Security Subsystem Class: Enterprise_A” specificatio n with
additional vendor-unique features as noted in this product manual.
3.1.1 Electromagnetic compatibility
The drive, as delivered, is designed for system integration and installation into a suitable enclosure prior to
use. The drive is supplied as a subasse mbly and is not s ubject to Subpart B o f Part 15 of the F CC Rules and
Regulations nor the Radio Interference Reg ula tio ns of the Canadian Department of Communications.
The design characteristics of the drive serve to minimize radiation when installed in an enclosure that provides
reasonable shielding. The drive is capable of meeting the Class B limits of the FCC Rules and Regulations of
the Canadian Department of Communications when properly packaged; however, it is the user’s responsibility
to assure that the drive meets the appropriate EMI requirements in their system. Shielded I/O cables may be
required if the enclosure does not provide adequate shielding. If the I/O cables are external to the enclosure,
shielded cables should be used, with the shields grounded to the enclosure and to the host controller.
3.1.1.1 Electromagnetic susceptibility
As a component assembly, the drive is not required to meet any susceptibility performance requirements. It is
the responsibility of those integrating the drive within their systems to perform those tests required and design
their system to ensure that equipment operating in the same system as the drive or external to the system
does not adversely affect the performance of the drive . See Tables 14, 15 and 16, for DC power requirements.
Cheetah 15K.7 SAS Product Manual, Rev. D 3
Page 10
3.2 Compliance
3.2.1 Electromagnetic compliance
Seagate uses an independent laboratory to confirm compliance with the directives/standards for CE Marking
and C-Tick Marking. The drive was teste d in a repr esent ative system for typical applications. The selected system represents the most popular characteristics for test platforms. The system configurations include:
• Typical current use microprocessor
• Keyboard
• Monitor/display
• Printer
•Mouse
Although the test system with this Seagate model complies with the directives/standards, we cannot guarantee
that all systems will comply. The computer manufacturer or system integrator shall confirm EMC compliance
and provide the appropriate marking for their product.
Electromagnetic compliance for the European Union
If this model has the CE Marking it complies with the European Union requirements of the Electromagnetic
Compatibility Directive 89/336/EEC of 03 May 1989 as amended by Directive 92/31/EEC of 28 April 1992 and
Directive 93/68/EEC of 22 July 1993.
Australian C-Tick
If this model has the C-Tick Marking it complies with the Australia/New Zealand Standard AS/NZS3548 1995
and meets the Electromagnetic Compatibility (EMC) Framework requirements of Australia’s Spectrum Management Agency (SMA).
Korean KCC
If this model has the Korean Communications Commission (KCC) logo, it complies with paragraph 1 of Article
11 of the Electromagnetic Compatibility (EMC) Control Regulation and meets the Electromagnetic Compatibility Framework requirements of the Radio Research Laboratory (RRL) Ministry of Information and Communication Republic of Korea
Taiwanese BSMI
If this model has two Chinese words meaning “EMC certification” followed by an eight digit identification number, as a Marking, it complies with Chinese National Standard (CNS) 13438 and meets the Electromagnetic
Compatibility (EMC) Framework requirements of the Taiwanese Bureau of Standards, Metrology, and Inspection (BSMI).
3.3 European Union Restriction of Hazardous Substances (RoHS)
The European Union Restriction of Hazardous Substances (RoHS) Directive restricts the presence of chemical
substances, including Lead (Pb), in electronic products effective July 2006.
A number of parts and materials in Seagate products are procured from external suppliers. We rely on the representations of our suppliers regarding the presence of RoHS substances in these parts and materials. Our
supplier contracts require compliance with our ch emical substance restrictions, and our suppliers document
their compliance with our requirements by providing material conten t declarations for all p arts and materials for
the disk drives documented in this publication. Current supplier declarations include disclosure of the inclusion
of any RoHS-regulated substance in such parts or materials.
4 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 11
Seagate also has internal systems in place to ensure on going compliance with the RoHS Directive and all laws
and regulations which restrict chemical content in electronic products. These systems include standard operating procedures that ensure that restricted substances are not utilized in our manufacturing operations, laboratory analytical validation testing, and an internal auditing process to ensure that all standard operating
procedures are complied with.
3.4 Reference documents
SCSI Commands Reference Manual Seagate part number: 100293068
SAS Interface Manual Seagate part number: 100293071
ANSI SAS documents
SFF-8323 3.5” Drive Form Factor with Serial Connector
SFF-8460 HSS Backplane Design Guidelines
SFF-8470 Multi Lane Copper Connector
SFF-8482 SAS Plug Connector
ANSI INCITS.xxx Serial Attached SCSI (SAS-2) Standard (T10/1562-D)
ISO/IEC 14776-xxx SCSI Architecure Model-4 (SAM-4) Standard (T10/1561-D)
ISO/IEC 14776-xxx SCSI Primary Commands-3 (SPC-3) Standard (T10/1416-D)
ISO/IEC 14776-xxx SCSI Block Commands-2 (SBC-2) St andard (T10/1417-D)
Trusted Computing Group (TCG) Documents (apply to SED models only)
TCG Core Specification, version 0.9
TCG SSC Specification (draft)
Self-Encrypting Drives Users Guide‘ Seagate part number: 100515636
Specification for Acoustic Test Requirement and Procedures Seagate part number: 30553-001
Package Test Specification Seagate P/N 30190-001 (under 100 lb.)
Package Test Specification Seagate P/N 30191-001 (over 100 lb.)
In case of conflict between this document and any referenced document, this document takes precedence.
Cheetah 15K.7 SAS Product Manual, Rev. D 5
Page 12
4.0 General description
Cheetah 15K.7 drives provide high pe rformance , high capacity data storag e for a variet y of systems inc luding
engineering workstations, network servers, mainframes, and supercomputers. The Serial Attached SCSI interface is designed to meet next-generation computing demands for performance, scalability, flexibility and highdensity storage requirements.
Cheetah 15K.7 drives support the Serial Attached SCSI Protocol as described in the ANSI specifications, this
document, and the SAS Interface Manual (part number 100293071) which describes the general interface
characteristics of this drive. Cheetah 15K.7 drives are classified as intelligent peripherals and provide level 2
conformance (highest level) with the ANSI SCSI-1 standard. The SAS connectors, cables and electrical interface are compatible with Serial ATA (SATA), giving future users the choice of populating their systems with
either SAS or SATA hard disk drives. This allows you to continue to leverage your existing investment in SCSI
while gaining a 3Gb/s serial data transfer rate.
Cheetah 15K.7 SAS SED models have provisions for “Security of Data at Rest” based on the standards
defined by the Trusted Computing Gr oup (see www.trustedcomputinggroup.org).
Note. Never disassemble the HDA and do not attempt to service items in the sealed enclosure (heads,
media, actuator, etc.) as this requires special facilities. The drive does not contain user-replaceable
parts. Opening the HDA for any reason voids your warranty.
Cheetah 15K.7 drives use a dedicated landing zone at the innermost radius of the media to eliminate the possibility of destroying or degrading data by landing in the data zone. The heads automatically go to the landing
zone when power is removed from the drive.
An automatic shipping lock prevents potential damage to the heads and disks that results from movement during shipping and handling. The shipping lock disengages and the head load process begins when power is
applied to the drive.
The drives also use a high-performance actuator assembly with a low-inertia, balanced, patented, straight arm
design that provides excellent performance with minimal power dissipation.
6 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 13
4.1 Standard features
Cheetah 15K.7 drives have the following standard features:
• 1.5 / 3 / 6 Gbit Serial Attached SCSI (SAS) interface
• Integrated dual port SAS controller supporting the SCSI protocol
• Support for SAS expanders and fanout adapters
• Firmware downloadable using the SAS interface
• 128 - deep task set (queue)
• Supports up to 32 initiators
• Jumperless configuration.
• User-selectable logical block size (512, 520, or 528 bytes per logical block)
• Programmable logical block reallocation scheme
• Flawed logical block reallocation at format time
• Programmable auto write and read reallocation
• Reallocation of defects on command (Post Format)
• ECC maximum burst correction length of 320 bits
• No preventive maintenance or adjustments required
• Dedicated head landing zone
• Embedded servo design
• Automatic shipping lock
• Self diagnostics performed when power is applied to the drive
• Zone bit recording
• Vertical, horizontal, or top down mounting
• Dynamic spindle brake
• 16 Mbyte data buffer
• Drive Self Test
• Background Media Scan
•Power Save
Cheetah 15K.7 SAS SED models have the following additional features:
• Automatic data encryption/decryption on all writes and reads to and from the media
• Controlled access
• Random number generator
• Drive locking
• Two independent data bands which each have it’s own ownership credential and encryption key
• Cryptographic erase of user data for a drive that will be repurposed or scrapped
• Authenticated firmware download
4.2 Media description
The media used on the drive has an aluminum substrate coated with a thin film magnetic material, overcoated
with a proprietary protective layer for improved durability and environmental protection.
4.3 Performance
• Programable multi-segmented cache buffer
• 600 Mbytes/sec maximum instantaneous data transfers
• 15k RPM spindle. Average latency = 2.0 msec
• Background processing of queue
• Supports start and stop commands (spindle stops spinning)
• Adaptive seek velocity; improved seek performance
Cheetah 15K.7 SAS Product Manual, Rev. D 7
Page 14
Note. There is no significant performance difference between Self-Encrypting Drive and standard (non-
Self-Encrypting Drive models.
4.4 Reliability
• 1,600,000 hour MTBF (Annualized Failure Rate (AFR) of 0.55%)
• Incorporates industry-standard Self-Monitoring Analysis and Reporting Technology (S.M.A.R.T.)
• 5-year warranty
4.5 Formatted capacities
Standard OEM models are formatted to 512 bytes per block. The block size is selectable at format time and
must be one of the supported sizes listed in the table below.
Seagate designs specify capacity points at certain block sizes that Seagate guarantees current and future
products will meet. We recommend customers use this capacity in their project planning, as it ensures a stable
operating point with backward and forward compatibility from generation to generation. The current guaranteed
operating points for this product are:
ST3600057SS
ST3600957SS
ST3600857SS
Sector Size
512 1,172,123,568 45DD2FB0 879,097,968 3465F870 585,937,500 22ECB25C
520 1,147,307,694 446286AE 860,480,771 3349E503 573,653,848 22314358
524 1,132,015,600 43792FF0 849,011,700 329AE3F4 566,007,800 21BC97F8
528 1,115,749,560 4280FCB8 836,812,167 31E0BD87 557,874,778 21407E5A
Decimal Hex Decimal Hex Decimal Hex
ST3450857SS
ST3450757SS
ST3450657SS
ST3300657FC
ST3300557FC
ST3300457SS
4.6 Programmable drive capacity
Using the Mode Select command, the drive can change its capacity to something less than maximum. See the
Mode Select (6) parameter list table in the SAS Interface Manual, part number 100293071. A value of zero in
the Number of Blocks field indicates that the drive will not change the capacity it is currently formatted to have.
A number other than zero and less than the maximum number of LBAs in the Number of Blocks field changes
the total drive capacity to the value in the Number of Blocks field. A value greater than the maximum number of
LBAs is rounded down to the maximum capacity.
4.7 Factory-installed options
You may order the following items which are incorporated at the manufacturing facility during production or
packaged before shipping. Some of the options available are (not an exhaustive list of possible options):
• Other capacities can be ordered depending on sparing scheme and sector size requested.
• Single-unit shipping pack. The drive is normally shipped in bulk packaging to provide ma ximum protection
against transit damage. Units shipped individually require additional protection as p rovided by the sin gle unit
shipping pack. Users planning single unit distribution should specify this option.
•The Safety and Regulatory Agency Specifications, part number 75789512, may be included with each stan-
dard OEM drive shipped.
8 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 15
5.0 Performance characteristics
This section provides detailed information concerning performance-related characteristics and features of
Cheetah 15K.7 drives.
5.1 Internal drive characteristics
ST3600057SS ST3450857SS ST3300657SS
ST3600957SS ST3450757SS ST3300557SS
ST3600857SS ST3450657SS ST3300457SS
Drive capacity 600 450 300 Gbytes (formatted, rounded off value)
Read/write data heads 8 6 4
Tracks per inch 165,000 165,000 165,000 TPI
Peak bits per inch 1,361 1,361 1,361 KBPI
Areal Density 225 225 225 Gbits/inch
Internal data rate 1.49 - 2.37 1.49 - 2.37 1.49 - 2.37 Gbits/sec (max)
Disk rotation speed 15k 15k 15 k RPM
Avg rotational latency 2.0 2.0 2.0 msec
*One Gbyte equals one billion bytes when referring to hard drive capacity. Accessible capacity may vary depending on operating environment
and formatting.
2
5.2 Seek time
*
See Section 12.4.1, "SAS physical interface" on page 58 and the SAS Interface Manual (part number
100293071) for additional timing details.
5.2.1 Access time
Not Including controller overhead
Read Write
Average Typical 3.4 3.9
Single track Typical 0.2 0.44
Full stroke Typical 6.6 7.4
1. Typical access times are measured under nominal conditions of temperature, voltage, and
horizontal orientation as measured on a representative sample of drives.
2. Access to data = access time + latency time.
1, 2
(msec)
Cheetah 15K.7 SAS Product Manual, Rev. D 9
Page 16
5.2.2 Format command execution time (minutes)
When changing sector sizes, the format times shown below may need to be increased by 30 minutes.
600GB 450GB 300GB
Maximum (with verify) 119 90 58
Maximum (without verify) 60 45 29
Note. There is approximately a 1.5 increase in time to format a SED drive versus a non-SED drive of the same capacity.
Execution time measured from receipt of the last byte of the Command Descriptor Block (CDB) to the request
for a Status Byte Transfer to the Initiator (excluding connect/disconnect).
5.2.3 General performance characteristics
Sustainable disk transfer rate*:
Minimum 122 Mbytes/sec (typical)
Maximum 204 Mbytes/sec (typical)
SAS Interface maximum instantaneous transfer rate 600 Mbytes/sec* per port
Logical block sizes
Default is 512-byte data blocks
Sector sizes variable to 512, 520, and 528 kbytes.
Read/write consecutive sectors on a track Yes
Flaw reallocation performance impact (for flaws reallocated at format time using
the spare sectors per sparing zone reallocation scheme.)
Average rotational latency 2.0 msec
*Assumes system ability to support the rates listed and no cable loss.
1 MB/sec = 1,000,000 bytes/sec
Negligible
5.3 Start/stop time
The drive accepts the commands listed in the SAS Interface Manual less than 3 seconds after DC power has
been applied.
If the drive receives a NOTIFY (ENABLE SPINUP) primitive through either port and has not received a START
STOP UNIT command with the START bit equal to 0, the drive becomes ready for normal operations within 20
seconds (excluding the error recovery procedure).
If the drive receives a START STOP UNIT command with the START bit equal to 0 before receiving a NOTIFY
(ENABLE SPINUP) primitive, the drive waits for a START ST OP UNIT command with the START bit equal to 1.
After receiving a START STOP UNIT command with the START bit equal to 1, the drive waits for a NOTIFY
(ENABLE SPINUP) primitive. After receiving a NOTIFY (ENABLE SPINUP) primitive through either port, the
drive becomes ready for normal operations within 20 seconds (excluding the error recovery procedure).
10 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 17
If the drive receives a START STOP UNIT command with the START bit and IMMED bit equal to 1 and does
not receive a NOTIFY (ENABLE SPINUP) primitive within 5 seconds, the drive fails the START STOP UNIT
command.
The ST AR T STOP UNIT command may be used to command the drive to stop the spindle. S top time is 30 se conds (maximum) from removal of DC power. There is no power control switch on the drive.
5.4 Prefetch/multi-segmented cache control
The drive provides a prefetch (read look-ahead) and multi-segmented cache control algorithms that in many
cases can enhance system performance. Cache refers to the drive buffer storage space when it is used in
cache operations. To select this feature, the host sends the Mode Select command with th e proper values in
the applicable bytes in page 08h. Prefetch and cache operations are independent features from the standpoint
that each is enabled and disabled independently using the Mode Select command; however, in actual operation, the prefetch feature overlaps cache operation somewhat as described in sections 5.5.1 and 5.5.2.
All default cache and prefetch mode parameter values (Mode Page 08h) for standard OEM versions of this
drive family are given in Section 12.3.2.1.
5.5 Cache operation
Note. Refer to the SAS Interface Manual for more detail concerning the cache bits.
Of the 16 Mbytes physical buffer space in the drive, approximately 13,000 kbytes can be used as a cache. The
buffer is divided into logical segments from which data is read and to which data is written.
The drive keeps track of the logical block addresses of the data stored in each segment of the buffer. If the
cache is enabled (see RCD bit in the SAS Interface Manual ), data requested by the host with a re ad command
is retrieved from the buffer, if possible, before any disk access is initiated. If cache operation is not enabled, the
buffer is still used, but only as circular buffer segments during disk medium read operations (disregarding
Prefetch operation for the moment). That is, the drive does not check in the buffer segments for the requested
read data, but goes directly to the medium to retrieve it. The retrieved data merely passes through some buffer
segment on the way to the host. All data transfers to the host are in accordance with buffer-full ratio rules. See
the explanation provided with the information about Mode Page 02h (disconnect/reconnect control) in the SAS
Interface Manual.
The following is a simplified description of the prefetch/cache operation:
Case A—read command is received and all of the requested logical blocks are already in the cache:
1. Drive transfers the requested logical blocks to the initiator.
Case B—A Read command requests data, and at least one requested logical block is not in any segment of
the cache:
1. The drive fetches the requested logical blocks from the disk and transfers them into a segment, and then
from there to the host in accordance with the Mode Select Disconnect/Reconnect parameters, page 02h.
2. If the prefetch feature is enabled, refer to section 5.5.2 for operation from this point.
Each cache segment is actually a self-contained circular buffer whose length is an integer number of logical
blocks. The drive dynamically creates and removes segments based on the workload. The wrap-around capability of the individual segments greatly enhances the cache’s overall performance.
Note. The size of each segment is not reported by Mode Sense command page 08h, bytes 14 and 15.
The value 0XFFFF is always reported regardless of the actual size of the segment. Sending a size
specification using the Mode Select command (bytes 14 and 15) does not set up a new segment
size. If the STRICT bit in Mode page 00h (byte 2, bit 1) is set to one, the drive responds as it does
for any attempt to change an unchangeable parameter.
Cheetah 15K.7 SAS Product Manual, Rev. D 11
Page 18
5.5.1 Caching write data
Write caching is a write operation by the drive that ma kes use o f a drive b uffer storage area wher e the da ta to
be written to the medium is stored while the drive performs the Write command.
If read caching is enabled (RCD=0), then data written to the medium is retained in the cache to be made available for future read cache hits. The same buffer space and segmentation is used as set up for read functions.
The buffer segmentation scheme is set up or changed independently, having nothing to do with the state of
RCD. When a write command is issued, if RCD=0, the cache is first checked to see if any logical blocks that
are to be written are already stored in the cache from a previous read or write command. If there are, the
respective cache segments are cleared. The new data is cached for subsequent Read commands.
If the number of write data logical blocks exceed the size of the se gment being written into, when the end of the
segment is reached, the data is written into the beginning of the same cache segment, overwriting the data that
was written there at the beginning of the operation; however, the drive does not overwrite data that has not yet
been written to the medium.
If write caching is enabled (WCE=1), then the drive may return Good status on a write command after the data
has been transferred into the cache, but before the data has been written to the medium. If an error occurs
while writing the data to the medium, and Good status has already been returned, a deferred error will be generated.
The Synchronize Cache command may be used to force the drive to write all cached write data to the medium.
Upon completion of a Synchronize Cache command, all data received from previous write commands will have
been written to the medium.
Table 12.3.2.1 shows the mode default settings for the drive.
5.5.2 Prefetch operation
If the Prefetch feature is enabled, data in contiguous logical blocks on the disk immediately beyond that which
was requested by a Read command are retrieved and stored in the buffer for immediate transfer from the buffer to the host on subsequent Read commands that request those logical blocks (this is true even if cache
operation is disabled). Though the pr ef etch operation uses the buffer as a cache, finding the requested data in
the buffer is a prefetch hit, not a cache operation hit.
To enable Prefetch, use Mode Select page 08h, byte 12, bit 5 (Disable Read Ahead - DRA bit). DRA bit = 0
enables prefetch.
The drive does not use the Max Prefetch field (bytes 8 and 9) or the Prefetch Ceiling field (bytes 10 and 11).
When prefetch (read look-ahead) is enabled (enabled by DRA = 0), the drive enables prefetch of contiguous
blocks from the disk when it senses that a prefetch hit will likely occur. The drive disables prefetch when it
decides that a prefetch hit is not likely to occur.
12 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 19
6.0 Reliability specifications
The following reliability specifications assume correct host and drive operational interface, including all interface timings, power supply voltages, environmental requirements and drive mounting constraints.
Seek error rate: Less than 10 errors in 10
Read Error Rates
Recovered Data Less than 10 errors in 10
Unrecovered Data Less than 1 sector in 10
Miscorrected Data Less than 1 sector in 10
Interface error rate: Less than 1 error in 10
MTBF 1,600,000 hours
AFR 0.55%
Preventive maintenance: None required
6.1 Error rates
The error rates stated in this manual assume the following:
• The drive is operated per this specification using DC power as defined in this manual (see Section 7.2).
• Errors caused by host system failures are excluded from error rate computations.
• Assume random data.
• Default OEM error recovery settings are applied. This includes AWRE, ARRE, full read retries, full write
retries and full retry time.
• Error rate specified with automatic retries and data correction with ECC enabled and all flaws reallocated
8
seeks
12
bits transferred (OEM default settings)
16
bits transferred
21
bits transferred
12
bits transferred
6.1.1 Recoverable Errors
Recoverable errors are those detected and corrected by the drive, and do not require user intervention.
Recoverable Data errors use retries and correction. Application of ECC on-the-fly correction alone is not con-
sidered a Recovered Data error.
Recovered Data error rate is determined using read bits transferred for recoverab le errors occurring during a
read, and using write bits transferred for recoverable errors occurring during a write.
6.1.2 Unrecoverable Errors
Unrecoverable Data Errors (Sense Key = 03h) are specified at less than 1 sector in error per 1016 bits transferred. Unrecoverable Data Errors resulting from the same cause are treated as 1 error for that block.
Cheetah 15K.7 SAS Product Manual, Rev. D 13
Page 20
6.1.3 Seek errors
A seek error is defined as a failure of the drive to position the heads to the addressed track. After detecting an
initial seek error, the drive automatically performs an error recovery process. If the error recovery process fails,
a seek positioning error (Error code = 15h or 02h) will be reported with a Hardware error (04h) in the Sense
Key. Recoverable seek errors are specified at Less than 10 errors in 10
8
seeks. Unrecoverable seek errors
(Sense Key = 04h) are classified as drive failures.
6.1.4 Interface errors
An interface error is defined as a failure of the receiver on a port to recover the data as transmitted by the
device port connected to the receiver. The error may be detected as a running disparity error, illegal code, loss
of word sync, or CRC error.
6.2 Reliability and service
You can enhance the reliability of Cheetah disk drives by ensuring that the drive receives adequate cooling.
Section 7.0 provides temperature measurements and other information that may be used to enhance the service life of the drive. Section 11.2 provides recommended air-flow information.
6.2.1 Annualized Failrue Rate (AFR) and Mean time between failure (MTBF)
These drives shall achieve an AFR of 0.55% (MTBF o f 1,600,000 hours) when operat ed in an environment th at
ensures the HDA case temperatures do not exceed the values specified in Section 7.4.
Operation at case temperatures outside the specifications in Section 7.4 may increase the AFR (decrease the
MTBF). AFR and MTBF statistics are population statistics that are not relevant to individual units.
AFR and MTBF specifications are based on the following assumptions for Enterprise Storage System environments:
• 8,760 power-on hours per year.
• 250 average on/off cycles per year.
• Operations at nominal voltages.
• Systems will provide adequate cooling to ensure the case temperatures specified in Sectio n 7.4.1 are not
exceeded.
6.2.2 Preventive maintenance
No routine scheduled preventive maintenance is required.
6.2.3 Hot plugging the drive
When a disk is powered on by switching the power or hot plugged, the drive runs a self test before attempting
to communicate on its’ interfaces. When the self test completes successfully, the drive initiates a Link Reset
starting with OOB. An attached device should respond to the link reset. If the link reset attempt fails, or any
time the drive looses sync, the drive initiated link reset. The drive will initiate link reset once per second but
alternates between port A and B. Therefore each port will attempt a link reset once per 2 seconds assuming
both ports are out of sync..
If the self-test fails, the does not respond to link reset on the failing port.
Note. It is the responsibility of the systems integrator to assure that no temperature, energy, voltage haz-
ard, or ESD potential hazard is presented during the hot connect/disconnect operation. Discharge
the static electricity from the drive carrier prior to inserting it into the system.
Caution. The drive motor must come to a complete stop prior to changing the plane of operation. This time is
required to insure data integrity.
14 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 21
6.2.4 S.M.A.R.T.
S.M.A.R.T. is an acronym for Self-Monitoring Analysis and Reporting Technology. This technology is intended
to recognize conditions that indicate imminent drive failure and is designed to provide sufficient warning of a
failure to allow you to back up the data before an actual failure occurs.
Note. The drive’s firmware monitors specific attributes for degrad ation over time but can’t predict inst ant a-
neous drive failures.
Each monitored attribute has been selected to monitor a specific set of failure conditions in the operating performance of the drive and the thresholds are optimized to minimize “false” and “failed” predictions.
Controlling S.M.A.R.T.
The operating mode of S.M.A.R.T. is controlled by the DEXCPT and PERF bits on th e Informational Exceptions
Control mode page (1Ch). Use the DEXCPT bit to enable or disable the S.M.A.R.T. feature. Setting the DEXCPT bit disables all S.M.A.R.T. functions. When enabled, S.M.A.R.T . collect s on-line data as the drive performs
normal read and write operations. When the PERF bit is set, the drive is considered to be in “On-line Mode
Only” and will not perform off-line functions.
You can measure off-line attributes and force the drive to save the data by using the Rezero Unit command.
Forcing S.M.A.R.T. resets the timer so that the next scheduled interrupt is in two hours.
You can interrogate the drive through the host to determine the time remaining before the next scheduled measurement and data logging process occurs. To accomplish this, issue a Log Sense command to log page 0x3E.
This allows you to control when S.M.A.R.T. interruptions occur. Forcing S.M.A.R.T. with the RTZ command
resets the timer.
Performance impact
S.M.A.R.T. attribute data is saved to the disk so that the events that caused a predict ive failure can be recreated. The drive measures and saves paramete rs once every two hours subject to an idle period on the drive
interfaces. The process of measuring off-line attribute data and saving data to the disk is uninterruptable. The
maximum on-line only processing delay is summarized below:
Maximum processing delay
S.M.A.R.T. delay times
On-line only delay
DEXCPT = 0, PERF = 1
42 milliseconds
Fully-enabled delay
DEXCPT = 0, PERF = 0
163 milliseconds
Cheetah 15K.7 SAS Product Manual, Rev. D 15
Page 22
Reporting control
Reporting is controlled by the MRIE bits in the Informational Exceptions Control mode page (1Ch). Subject to
the reporting method, the firmware will issue to the host an 01-5Dxx sense code. The error code is preserved
through bus resets and power cycles.
Determining rate
S.M.A.R.T. monitors the rate at which errors occur and signals a predictive failure if the rate of d eg raded erro rs
increases to an unacceptable level. To determine rate, error events are logged and compared to the number of
total operations for a given attribute. The interval defines the number of operations o ver whic h to m easur e the
rate. The counter that keeps track of the current number of operations is referred to as the Interval Counter.
S.M.A.R.T. measures error rates. All errors for each monitored attribute are recorded. A counter keeps track of
the number of errors for the current interval. This counter is referred to as the Failure Counter.
Error rate is the number of errors per operation. The algori thm that S.M.A.R.T. uses to record rates of erro r is to
set thresholds for the number of errors and their interval. If the number of errors exceeds the threshold before
the interval expires, the error rate is considered to be unacceptable. If the number of errors does not exceed
the threshold before the interval expires, the error rate is considered to be acceptable. In either case, the interval and failure counters are reset and the process starts over.
Predictive failures
S.M.A.R.T. signals predictive failures when the drive is performing unacceptably for a period of time. The firmware keeps a running count of the number of times the error rate for each attribute is unacceptable. To accomplish this, a counter is incremented e ach time the erro r rate is unacceptable and decremented (not to exceed
zero) whenever the error rate is acceptable. If the counter continually increments such that it reaches the predictive threshold, a predictive failure is signaled. This counter is referred to as the Failure History Counter.
There is a separate Failure History Counter for each attribute.
6.2.5 Thermal monitor
Cheetah 15K.7 drives implement a temperature warning system which:
1. Signals the host if the temperature exceeds a value which would threaten the drive.
2. Signals the host if the temper ature exceeds a user-specified value.
3. Saves a S.M.A.R.T. data frame on the drive which exceeds the threatening temperature value.
A temperature sensor monitors the drive temperature and issues a warning over the interface when the temperature exceeds a set th reshold. The t emperature is measured a t power-up an d then at te n-minute interv als
after power-up.
The thermal monitor system generates a warning code of 01-0B01 when the temperature exceeds the specified limit in compliance with the SCSI standard. The drive temperature is reported in the FRU code field of
mode sense data. You can use this information to determine if the warning is due to the temperature exceeding
the drive threatening temperature or the user-specified temperature.
This feature is controlled by the Enable Warning (EWasc) bit, and the re porting mecha nism is controlle d by th e
Method of Reporting Informational Exceptions field (MRIE) on the Informational Exceptions Control (IEC)
mode page (1Ch).
The current algorithm implem ents two temperature trip points. The first trip point is set at 68°C which is the
maximum temperature limit according to the drive specification. The second trip point is user-selectable using
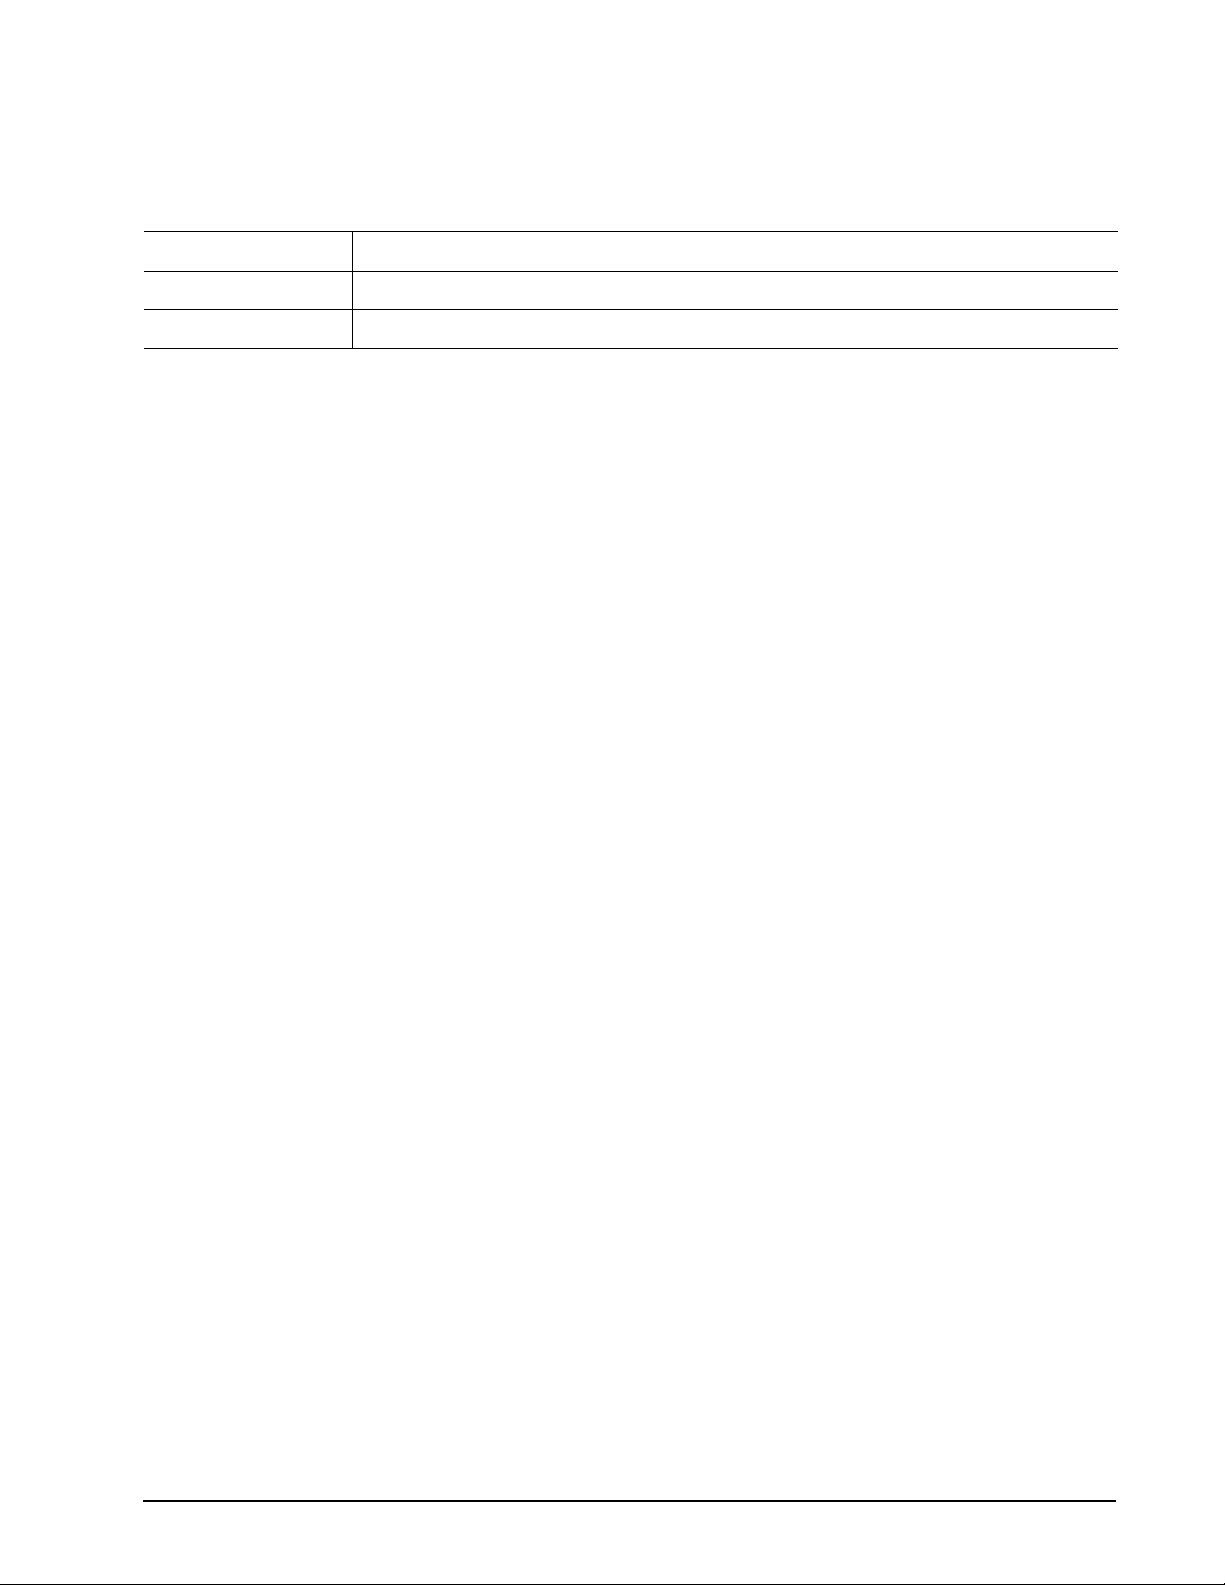
the Log Select command. T he reference temperature paramet er in the temperature log page (s ee Table 13)
16 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 23
can be used to set this trip point. The default value for this d rive is 68 °C, however, you can set it to any value in
the range of 0 to 68°C. If you specify a temperature greater than 68°C in this field, the temperature is rounded
down to 68°C. A sense code is sent to the host to indicate the rounding of the parameter field.
Table 13: Temperature Log Page (0Dh)
Parameter Code Description
0000h
0001h
Primary Temperature
Reference Temperature
6.2.6 Drive Self Test (DST)
Drive Self Test (DST) is a technology designed to recognize drive fault conditions that qualify the drive as a
failed unit. DST validates the functionality of the drive at a system level.
There are two test coverage options implemented in DST:
1. Extended test
2. Short test
The most thorough option is the extended test that performs various tests on the drive and scans ev er y lo gic al
block address (LBA) of the drive. The short test is time-restricted and limited in length—it does not scan the
entire media surface, but does some fundamental tests and scans portions of the media.
If DST encounters an error during either of these tests, it reports a fault condition. If the drive fails the test,
remove it from service and return it to Seagate for service.
6.2.6.1 DST failure definition
The drive will present a “diagnostic failed” condition through the self-tests results value of the diagnostic log
page if a functional failure is encountered during DST. The channel and servo parameters are not modified to
test the drive more stringently, and the number of retries are not reduced. All retries and recovery processes
are enabled during the test. If data is recoverable, no failure condition will be reported regardless of the number
of retries required to recover the data.
The following conditions are considered DST failure conditions:
• Seek error after retries are exhausted
• Track-follow error after retries are exhausted
• Read error after retries are exhausted
• Write error after retries are exhausted
Recovered errors will not be reported as diagnostic failures.
6.2.6.2 Implementation
This section provides all of the information necessary to implement the DST function on this drive.
6.2.6.2.1 State of the drive prior to testing
The drive must be in a ready state before issuing the Send Diagnostic command. There are multiple reasons
why a drive may not be ready, some of which are valid conditions, and not errors. For example, a drive may be
in process of doing a format, or another DST. It is the responsibility of the host application to determine the “not
ready” cause.
While not technically part of DST, a Not Ready condition also qualifies the drive to be returned to Seagate as a
failed drive.
A Drive Not Ready condition is reported by the drive under the following conditions:
Cheetah 15K.7 SAS Product Manual, Rev. D 17
Page 24
• Motor will not spin
• Motor will not lock to speed
• Servo will not lock on track
• Drive cannot read configuration tables from the disk
In these conditions, the drive responds to a Test Unit Ready command with an 02/04/00 or 02/04/03 code.
6.2.6.2.2 Invoking DST
To invoke DST, submit the Send Diagnostic command with the appropriate Function Code (001b for the short
test or 010b for the extended test) in bytes 1, bits 5, 6, and 7.
6.2.6.2.3 Short and extended tests
DST has two testing options:
1. short
2. extended
These testing options are described in the following two subsections.
Each test consists of three segments: an electrical test segment, a servo test segment, and a read/ve rify s can
segment.
Short test (Function Code: 001b)
The purpose of the short test is to provide a time-limited test that tests as much of the drive as possible within
120 seconds. The short test does not scan the entire media surface, but does some fundamental tests and
scans portions of the media. A complete read/verify scan is not performed and only factual failures will report a
fault condition. This option provides a quick confidence test of the drive.
Extended test (Function Code: 010b)
The objective of the extended test option is to empirically test critical drive componen ts. For example, the seek
tests and on-track operations test the positioning mechanism. The read operation tests the read head element
and the media surface. The write element is tested through read/write/read operations. The integrity of the
media is checked through a read/verify scan of the media. Motor functionality is tested by default as a part of
these tests.
The anticipated length of the Extended test is reported through the Control Mode page.
6.2.6.2.4 Log page entries
When the drive begins DST, it creates a new entry in the Self-test Results Log page. The new entry is created
by inserting a new self-test parameter block at the b eginning of the self- test result s log parame ter section of the
log page. Existing data will be moved to make room for the new parameter block. The drive reports 20 parameter blocks in the log page. If there are more than 20 parameter blocks, the least recent parameter block will be
deleted. The new parameter block will be initialized as follows:
1. The Function Code field is set to the same value as sent in the DST command
2. The Self-Test Results Value field is set to Fh
3. The drive will store the log page to non-volatile memory
After a self-test is complete or has been aborted, the drive updates the Self-Test Results Value field in its SelfTest Results Log page in non-volatile memory. The host may use Log Sense to read the results from up to the
last 20 self-tests performed by the drive. Th e se lf- te st r esults value is a 4-bit field that reports the results of the
test. If the field is set to zero, the drive passed with no errors detected by the DST. If the field is not set to zero,
the test failed for the reason reported in the field.
The drive will report the failure condition and LBA (if applicable) in the Self-test Results Log parameter. The
Sense key, ASC, ASCQ, and FRU are used to report the failure condition.
18 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 25
6.2.6.2.5 Abort
There are several ways to abort a diagnostic. You can use a SCSI Bus Reset or a Bus Device Reset message
to abort the diagnostic.
You can abort a DST executing in background mode by using the abort code in the DST Function Code field.
This will cause a 01 (self-test aborted by the application client) code to appear in the self-test results values
log. All other abort mechanisms will be reported as a 02 (self-test routine was interrupted by a reset condition).
6.2.7 Product warranty
Beginning on the date of shipment to the customer and continuing for the period specified in your purchase
contract, Seagate warrants that each product (including components and subassemblies) that fails to function
properly under normal use due to defect in materia ls or workmanshi p or due to noncon formance to the applicable specifications will be repaired or replaced, at Seagate’s option and at no charge to the customer , if returned
by customer at customer’s expense to Seagate’s designated facility in accordance with Seagate’s warranty
procedure. Seagate will pay for transporting the repair or replacement item to the customer. For more detailed
warranty information, refer to the standard terms and conditions of purchase for Seagate products on your purchase documentation.
The remaining warranty for a particular drive can be determined by calling Seagate Customer Service at
1-800-468-3472. You can also determine remaining warranty using the Seagate web site (www.seagate.com).
The drive serial number is required to determine remaining warranty information.
Shipping
When transporting or shipping a drive, use only a Seagate-approved container. Keep your original box. Seagate approved containers are easily identified by the Seagate Approved Package label. Shipping a drive in a
non-approved container voids the drive warranty.
Seagate repair centers may refuse receipt of components improperly packaged or obviously damaged in transit. Contact your authorized Seagate distributor to purchase additional boxes. Seagate recommends shipping
by an air-ride carrier experienced in handling computer equipment.
Product repair and return information
Seagate customer service centers are the only facilities authorized to service Seagate drives. Seagate does
not sanction any third-party repair facilities. Any unauthorized repair or tampering with the factory seal voids
the warranty.
Cheetah 15K.7 SAS Product Manual, Rev. D 19
Page 26
7.0 Physical/electrical specifications
This section provides information relating to the physical and electrical characteristics of the drive.
7.1 AC power requirements
None.
7.2 DC power requirements
The voltage and current requirements for a single drive are shown below. Values indicated apply at the drive
connector.
The standard drive models and the SED drive models have identical hardware, however the security and
encryption portion of the drive controller ASIC is enabled and functional in the SED models. This represents a
small additional drain on the 5V supply of about 30mA and a commensurate increase of about 150mW in
power consumption. There is no additional drain on the 12V supply.
20 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 27
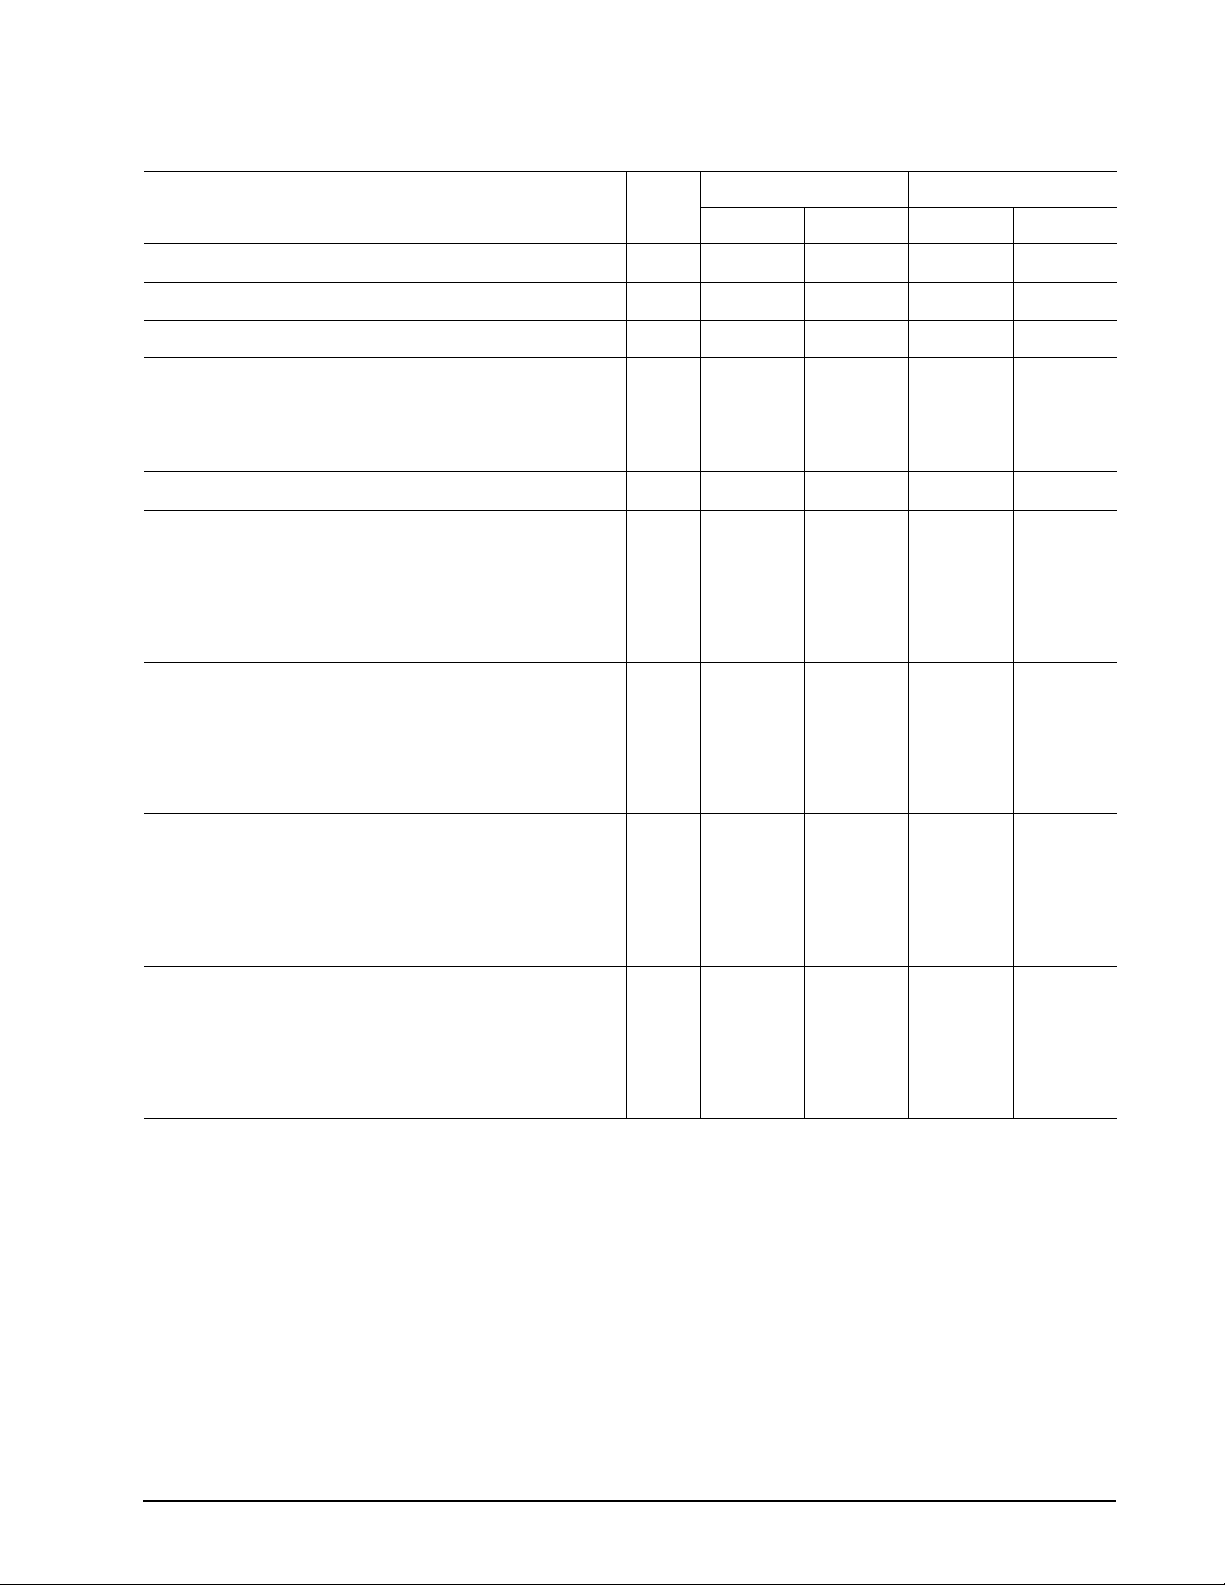
Table 14:
600 GB DC power requirements
3 Gbit mode 6 Gbit mode
Notes
Voltage +5V +12V [2] +5V +12V [2]
Regulation [5] ±5% ±5% [2] ±5% ±5% [2]
Avg idle current [1] [7] 0.37 0.81 0.38 0.81
Maximum starting current
(peak DC) DC 3σ [3]0.671.900.681.91
(peak AC) AC 3σ [3]0.983.820.983.88
Delayed motor start (max) DC 3σ [1] [4] 0.55 0.04 0.56 0.04
Peak operating current (random read):
Typical DC [1][6] [1] 0.44 1.15 0.45 1.17
Maximum DC 3σ [1]0.491.200.511.21
Maximum DC (peak) 3σ 1.32 3.00 1.34 3.00
Peak operating current (random write):
Typical DC [1][6] [1] 0.51 1.03 0.53 1.04
Maximum DC 3σ [1]0.561.050.581.07
Maximum DC (peak) 3σ 1.26 2.94 1.28 2.92
(Amps) (Amps) (Amps) (Amps)
Peak operating current (sequential read):
Typical DC [1][6] [1] 0.98 0.83 0.99 0.84
Maximum DC 3σ [1]1.080.841.100.85
Maximum DC (peak) 3σ 1.40 1.26 1.46 1.24
Peak operating current (sequential write):
Typical DC [1][6] [1] 0.93 0.83 0.94 0.83
Maximum DC 3σ [1]1.000.841.020.85
Maximum DC (peak) 3σ 1.30 1.24 1.30 1.26
Cheetah 15K.7 SAS Product Manual, Rev. D 21
Page 28
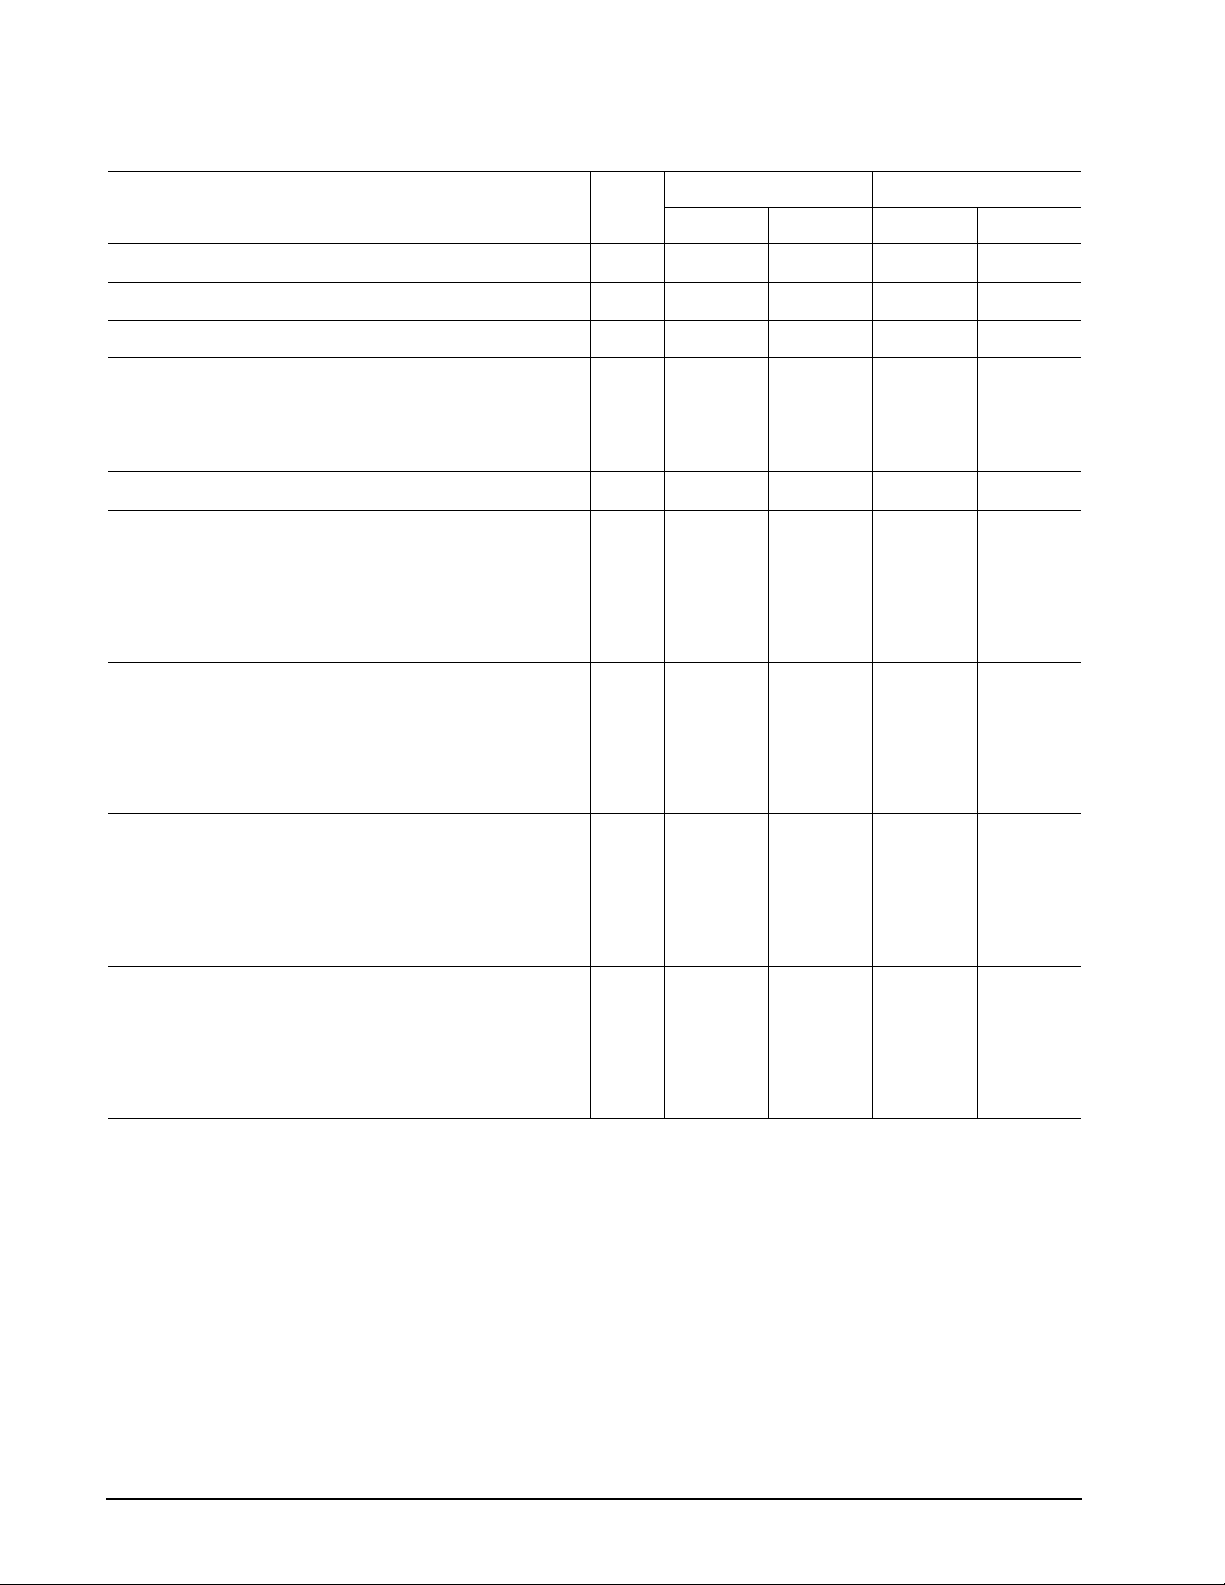
Table 15:
450 GB DC power requirements
3 Gbit mode 6 Gbit mode
Notes
Voltage +5V +12V [2] +5V +12V [2]
Regulation [5] ±5% ±5% [2] ±5% ±5% [2]
Avg idle current [1] [7] 0.39 0.68 0.41 0.66
Maximum starting current
(peak DC) DC 3σ [3]0.651.940.671.94
(peak AC) AC 3σ [3]0.943.910.963.89
Delayed motor start (max) DC 3σ [1] [4] 0.54 0.04 0.56 0.04
Peak operating current (random read):
Typical DC [1][6] [1] 0.45 1.01 0.47 1.02
Maximum DC 3σ [1]0.481.080.511.06
Maximum DC (peak) 3σ 1.28 2.90 1.30 2.84
Peak operating current (random write):
Typical DC [1][6] [1] 0.52 0.90 0.55 0.89
Maximum DC 3σ [1]0.560.930.580.91
Maximum DC (peak) 3σ 1.24 2.78 1.26 2.84
(Amps) (Amps) (Amps) (Amps)
Peak operating current (sequential read):
Typical DC [1][6] [1] 0.98 0.69 1.03 0.67
Maximum DC 3σ [1]1.040.701.100.68
Maximum DC (peak) 3σ 1.36 1.10 1.44 1.10
Peak operating current (sequential write):
Typical DC [1][6] [1] 0.95 0.69 0.98 0.67
Maximum DC 3σ [1]0.990.701.020.68
Maximum DC (peak) 3σ 1.26 1.10 1.30 1.12
22 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 29
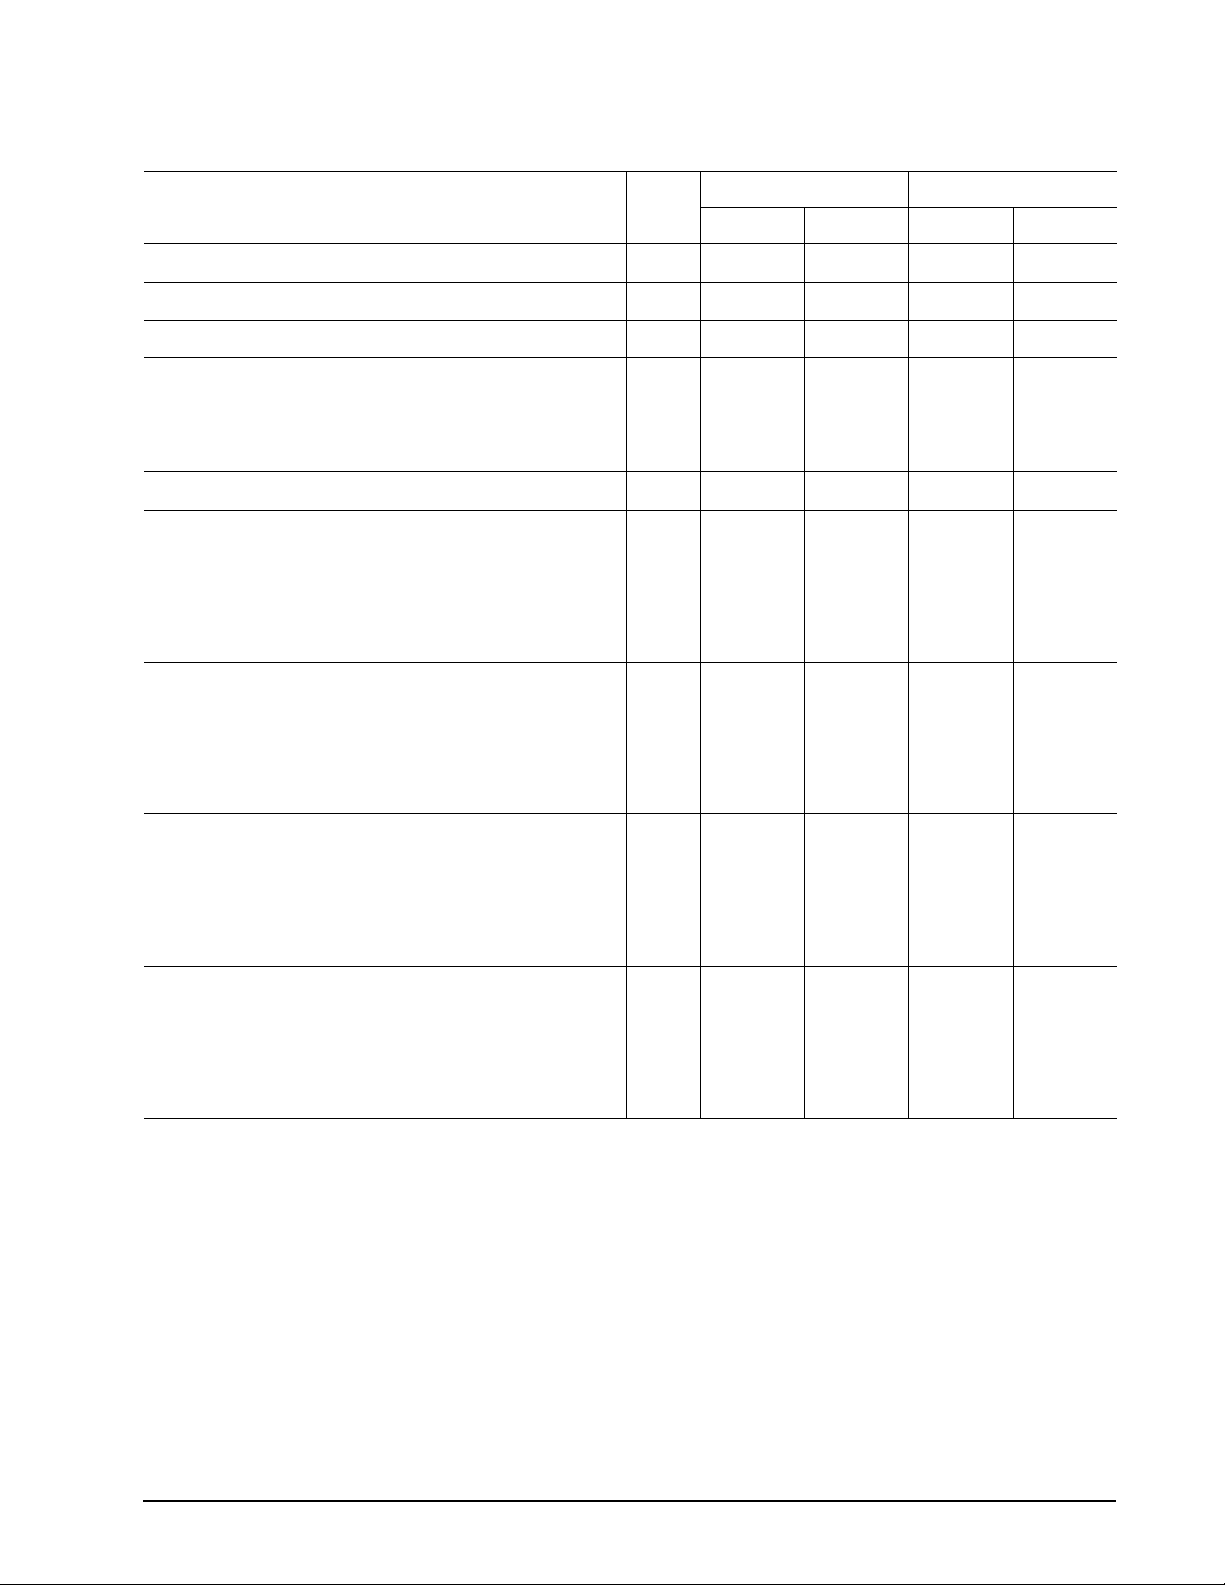
Table 16: 300 GB DC power requirements
3 Gbit mode 6 Gbit mode
Notes
Voltage +5V +12V [2] +5V +12V [2]
Regulation [5] ±5% ±5% [2] ±5% ±5% [2]
Avg idle current [1] [7] 0.34 0.58 0.35 0.58
Maximum starting current
(peak DC) DC 3σ [3]0.531.920.541.92
(peak AC) AC 3σ [3]0.983.820.863.98
Delayed motor start (max) DC 3σ [1] [4] 0.47 0.04 0.48 0.04
Peak operating current (random read):
Typical DC [1][6] [1] 0.41 0.88 0.42 0.90
Maximum DC 3σ [1]0.420.950.430.95
Maximum DC (peak) 3σ 1.18 2.78 1.20 2.74
Peak operating current (random write):
Typical DC [1][6] [1] 0.48 0.80 0.49 0.81
Maximum DC 3σ [1]0.490.830.510.82
Maximum DC (peak) 3σ 1.18 2.68 1.20 2.66
(Amps) (Amps) (Amps) (Amps)
Peak operating current (sequential read):
Typical DC [1][6] [1] 0.91 0.59 0.92 0.59
Maximum DC 3σ [1]0.930.600.940.61
Maximum DC (peak) 3σ 1.20 0.98 1.24 1.00
Peak operating current (sequential write):
Typical DC [1][6] [1] 0.89 0.58 0.90 0.59
Maximum DC 3σ [1]0.930.600.940.60
Maximum DC (peak) 3σ 1.22 0.98 1.22 0.96
[1] Measured with average reading DC ammeter or equivalent sampling scope. Instantaneous +12V current
peaks will exceed these values. Power supply at nominal voltage. N (number of drives tested) = 6, 35
Degrees C ambient.
[2] For +12 V, a –10% tolerance is allowed during initial spindle start but must return to ±5% before reaching
15,000 RPM. The ±5% must be maintained after the drive signifies that its power-up sequence has been
completed and that the drive is able to accept selection by the host initiator.
[3] See +12V current profile in Figure 1.
[4] This condition occurs after OOB and Speed Negotiation completes but before the drive has received the
Notify Spinup primitive.
[5] See paragraph 7.2.1, "Conducted noise immunity." Specified voltage tolerance includes ripple, noise, and
transient response.
Cheetah 15K.7 SAS Product Manual, Rev. D 23
Page 30
[6] Operating condition is defined as random 8 block reads at 375 I/Os per second for 600GB models, and
380 I/Os per second for 450GB and 300GB models. Current and power specified at nominal voltages.
[7] During idle, the drive heads are relocated every 60 seconds to a random location within the band from
three-quarters to maximum track.
General DC power requirement notes.
1. Minimum current loading for each supply voltage is not less than 1.7% of the maxim um operating current
shown.
2. The +5V and +12V supplies should employ separate ground returns.
3. Where power is provided to multiple drives from a common supply, careful consideration for individual
drive power requirements should be noted. Where multiple units are powered on simultaneously, the peak
starting current must be available to each device.
4. Parameters, other than spindle start, are measured after a 10-minute warm up.
5. No terminator power.
7.2.1 Conducted noise immunity
Noise is specified as a periodic and random distribution of frequencies covering a band from DC to 10 MHz.
Maximum allowed noise values given below are peak-to-peak measurements and apply at the drive power
connector.
+5V = 250 mV pp from 0 to 100 kHz to 20 MHz.
+12V = 800 mV pp from 100 Hz to 8 KHz.
450 mV pp from 8 KHz to 20 KHz.
250 mV pp from 20 KHz to 5 MHz.
7.2.2 Power sequencing
The drive does not require power sequencing. The drive protects against inadvertent writing during power-up
and down.
7.2.3 Current profiles
The +12V and +5V current profiles are shown below in the following figures.
Note: All times and currents are typical. See Tables 14, 15, and 16 for maximum current requirements.
24 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 31
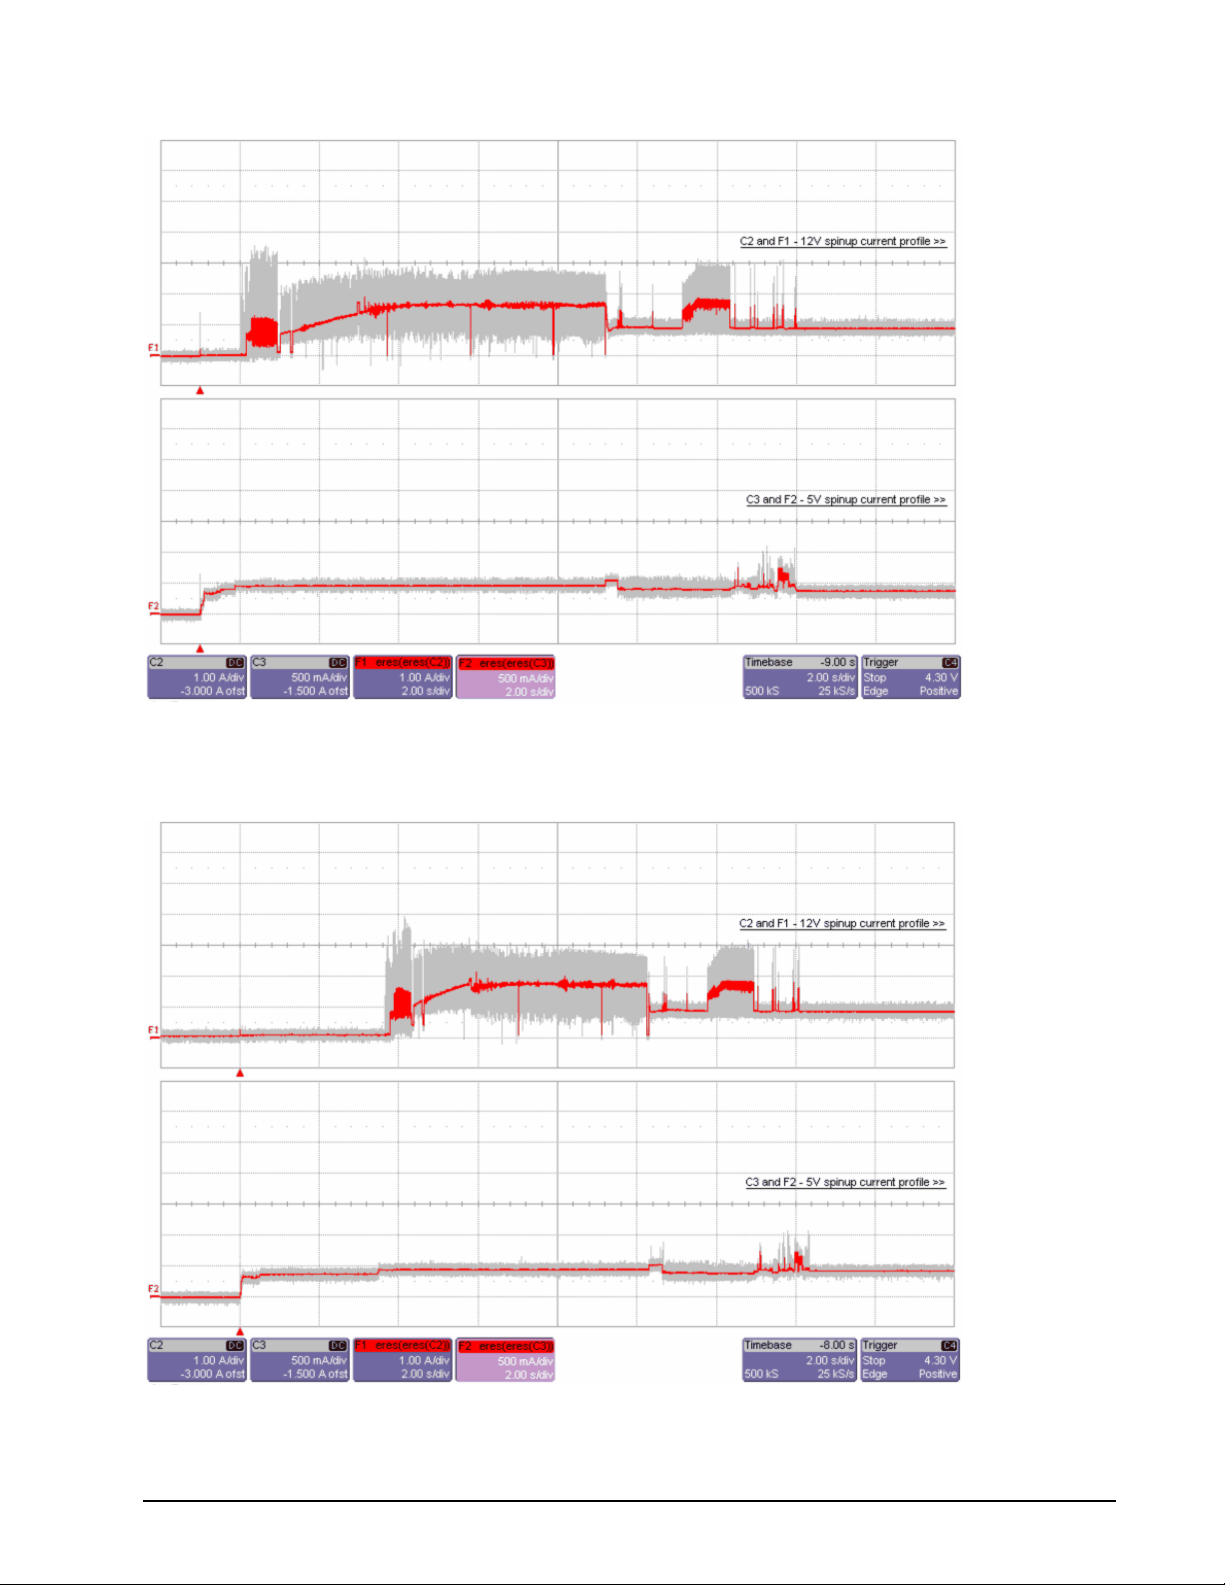
Figure 1. Typical 600GB current profiles
Figure 2. Typical 450GB current profiles
Cheetah 15K.7 SAS Product Manual, Rev. D 25
Page 32
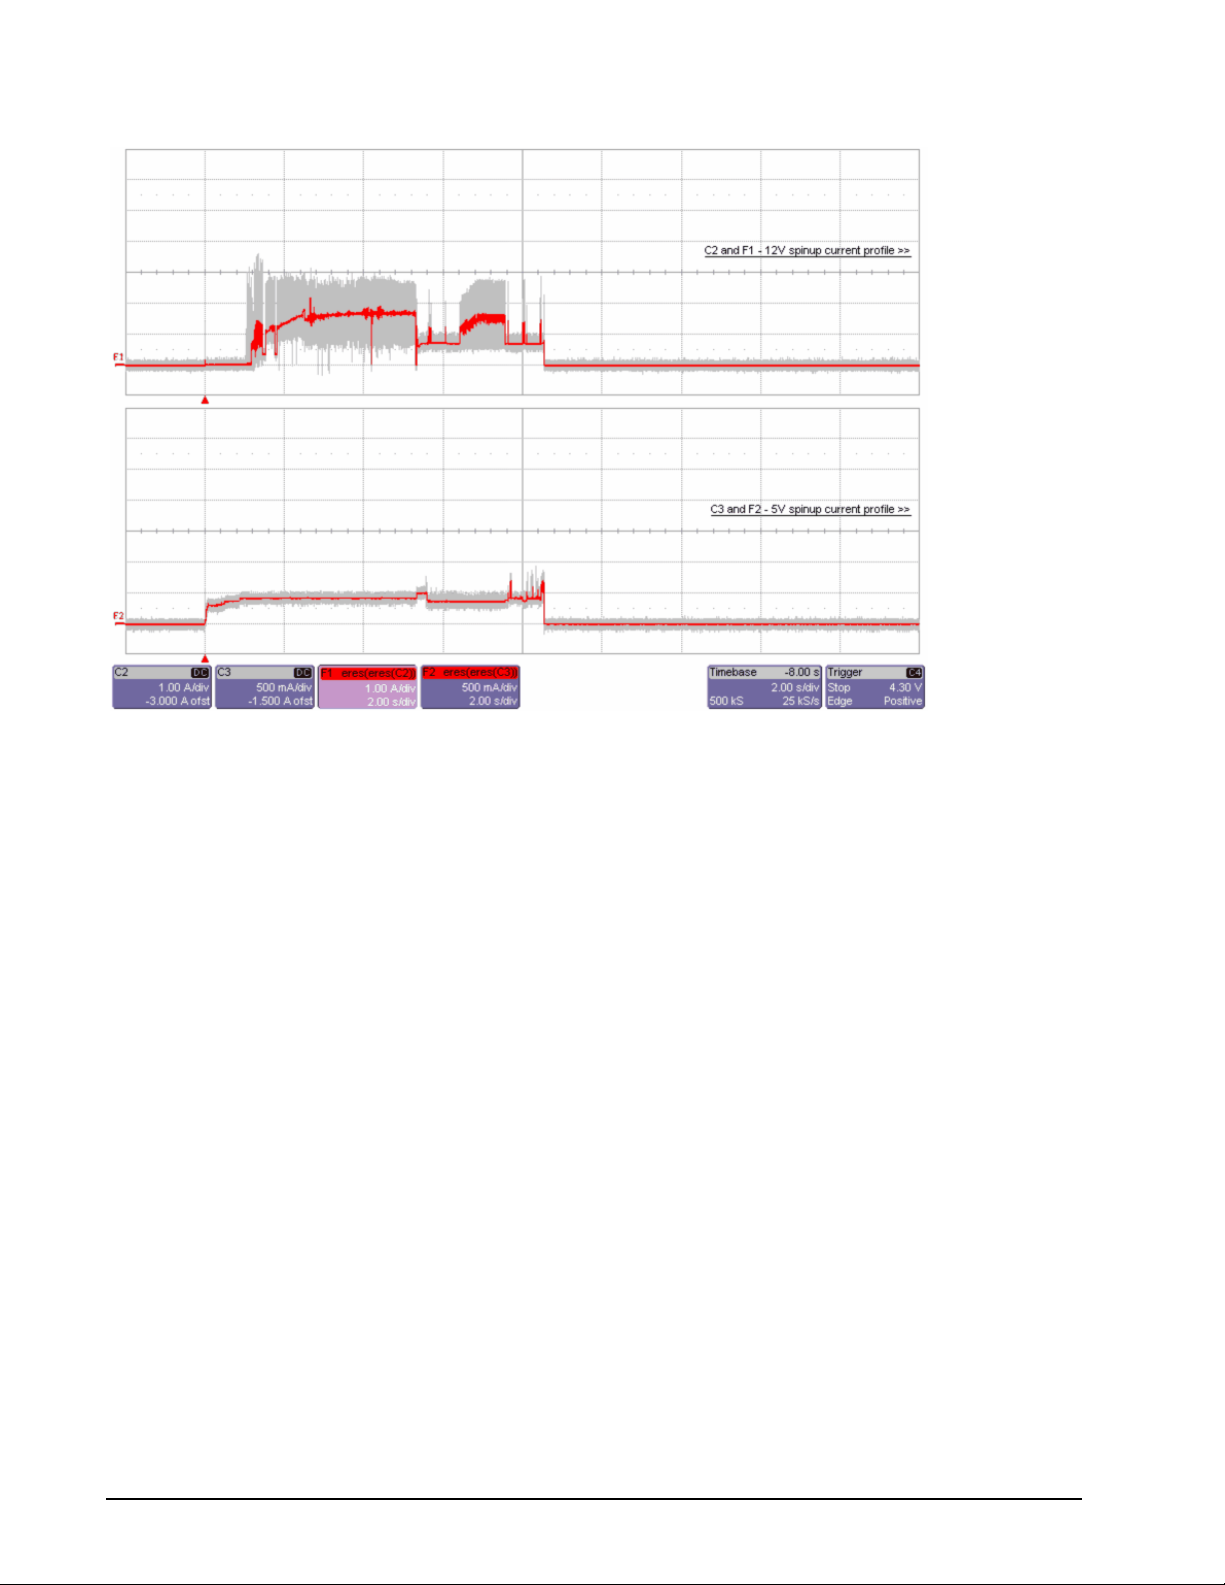
Figure 3. Typical 300GB current profiles
26 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 33
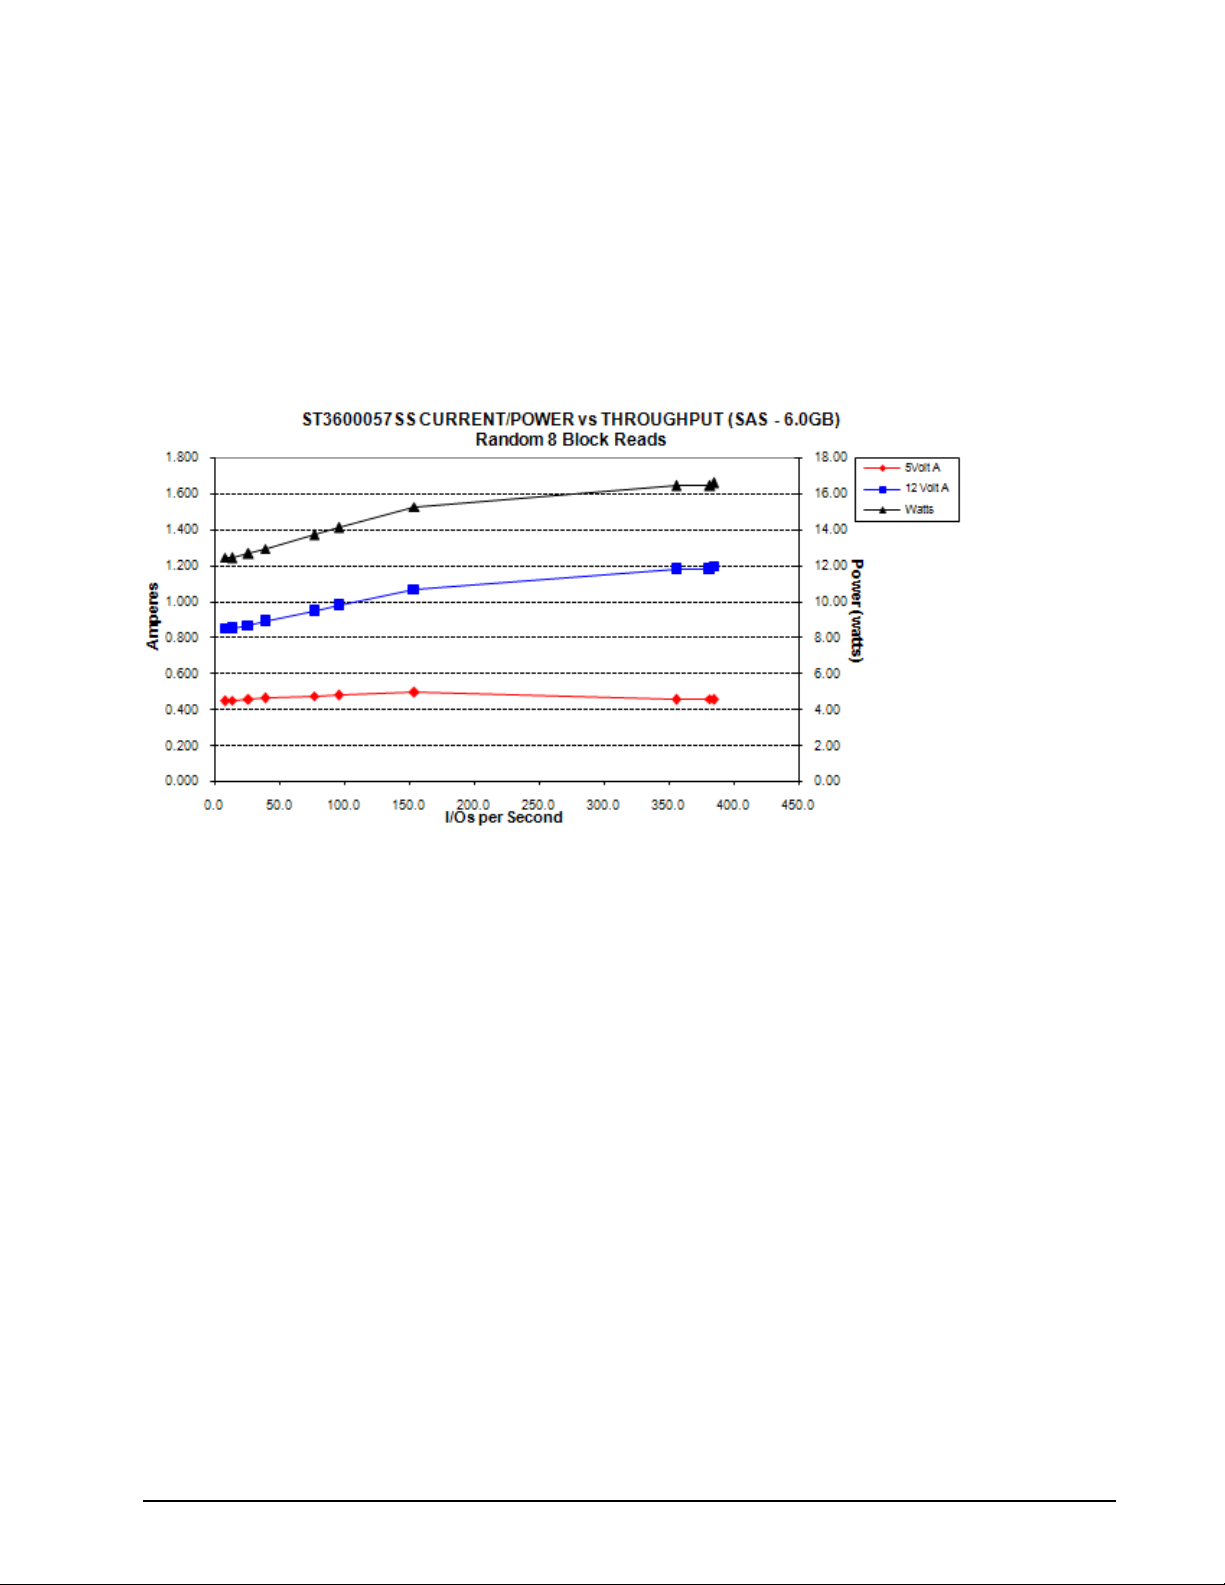
7.3 Power dissipation
600GB model
Typical power dissipation under idle conditions in 6Gb operation is 11.62 watts (39.65 BTUs per hour).
To obtain operating power for typical random read operations, refer to the following I/O rate curve (see Figure
4). Locate the typical I/O rate for a drive in y our system on the horizontal axis and read the corresponding +5
volt current, +12 volt current, and total watts on the vertical axis. To calculate BTUs per hour, multiply watts by
3.4123.
Figure 4. ST3600057SS DC current and power vs. input/output operations per second
Cheetah 15K.7 SAS Product Manual, Rev. D 27
Page 34
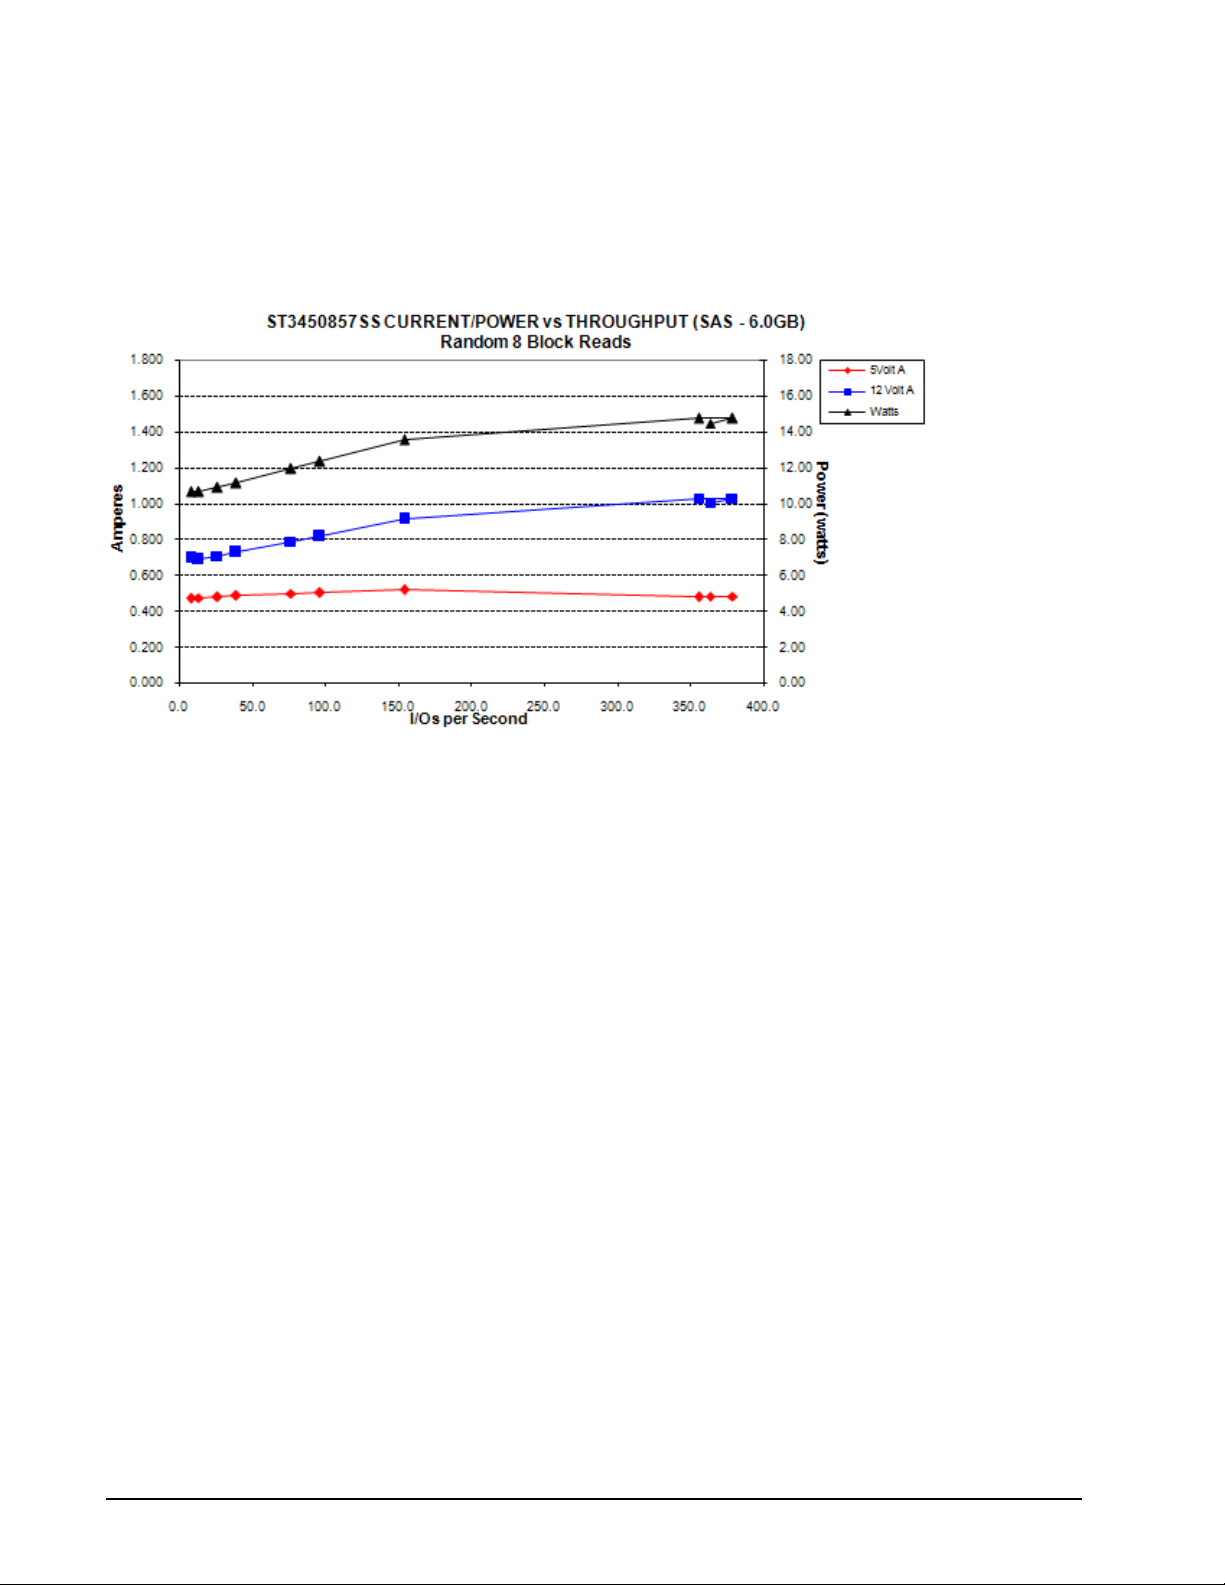
450GB model
Typical power dissipation under idle conditions in 6Gb operation is 9.97 watts (34.02 BTUs per hour).
To obtain operating power for typical random read operations, refer to the following I/O rate curve (see Figure
4). Locate the typical I/O rate for a drive in y our system on the horizontal axis and read the corresponding +5
volt current, +12 volt current, and total watts on the vertical axis. To calculate BTUs per hour, multiply watts by
3.4123.
Figure 5. ST3450857SS DC current and power vs. input/output operations per second
28 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 35
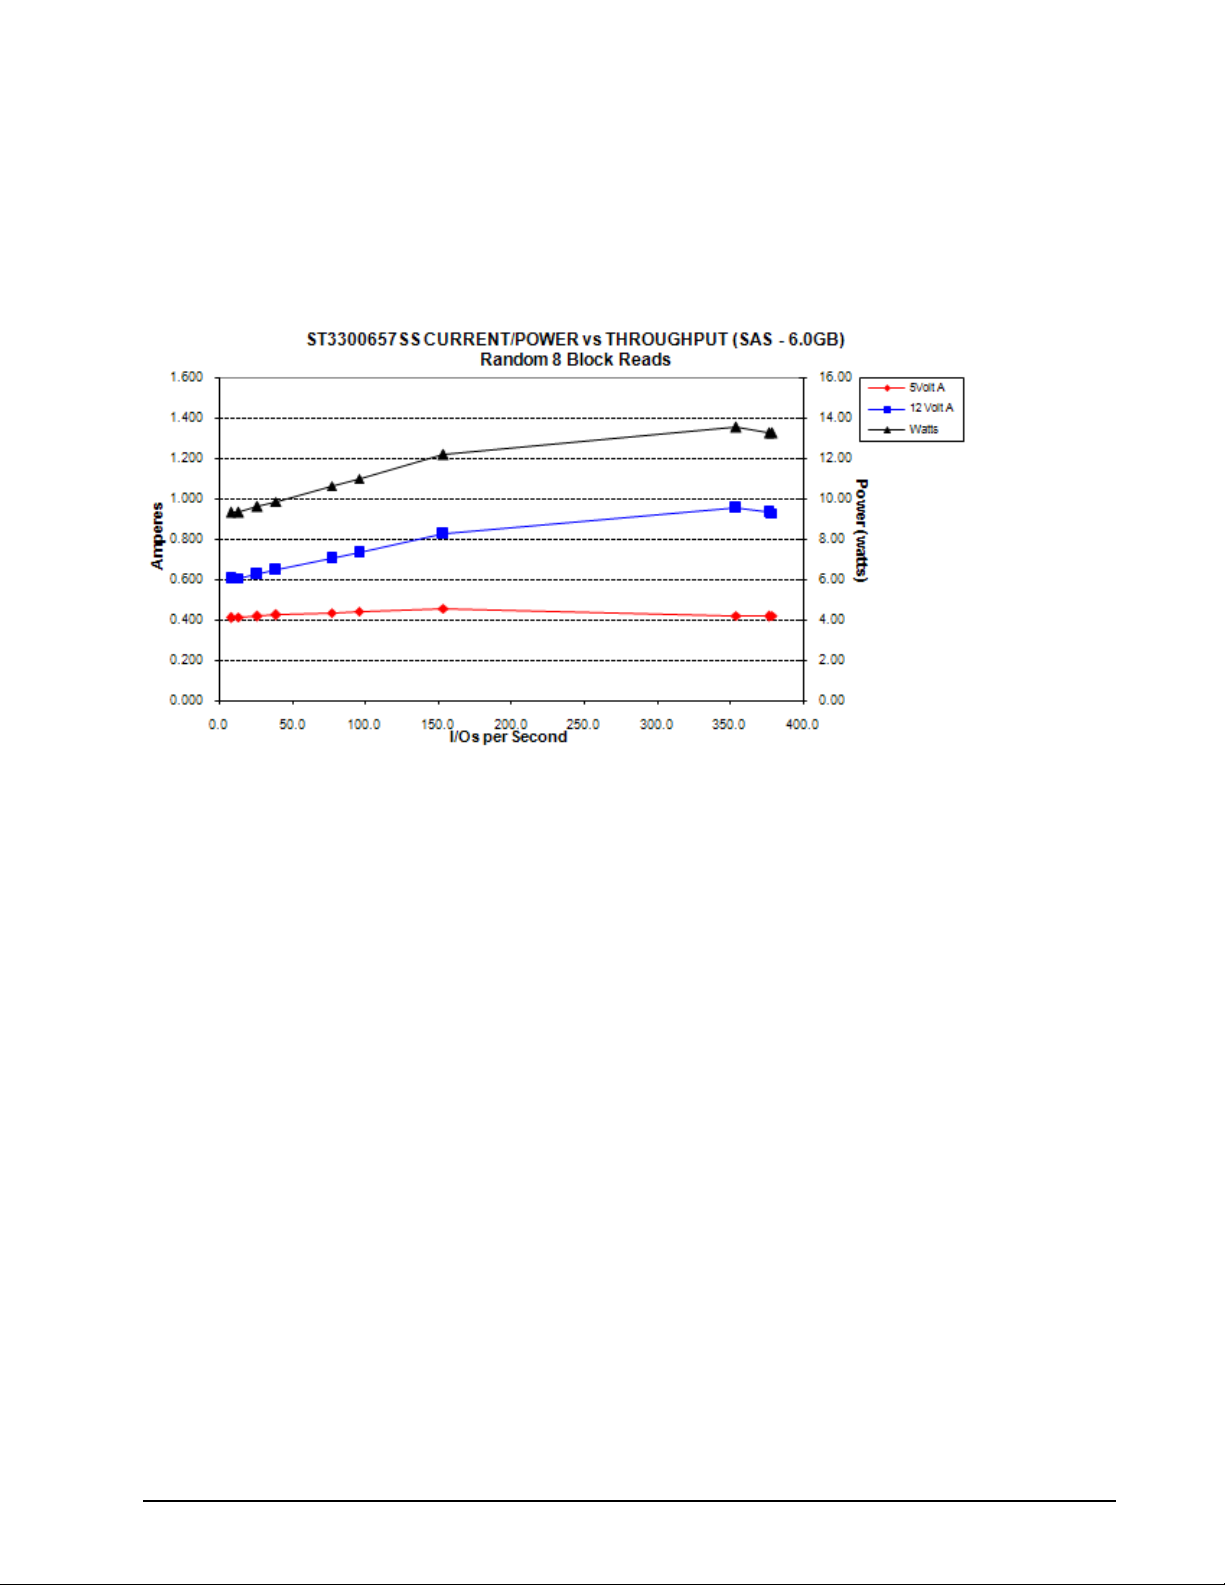
300GB model
Typical power dissipation under idle conditions in 6Gb operation is 8.71 watts (29.72 BTUs per hour).
To obtain operating power for typical random read operations, refer to the following I/O rate curve (see Figure
4). Locate the typical I/O rate for a drive in y our system on the horizontal axis and read the corresponding +5
volt current, +12 volt current, and total watts on the vertical axis. To calculate BTUs per hour, multiply watts by
3.4123.
Figure 6. ST3300657SS DC current and power vs. input/output operations per second
7.4 Environmental limits
Temperature and humidity values experienced by the drive must be such that condensation does not occur on
any drive part. Altitude and atmospheric pressure specifications are referenced to a standard day at 58.7°F
(14.8°C). Maximum wet bulb temperature is 82°F (28°C).
7.4.1 Temperature
a. Operating
The maximum allowable continuous or sustained HDA case temperature for the rated Annualized Failure
Rate (AFR) is 122°F (50°C) The maximum allowable HDA case temperature is 60°C. Occasional excur
sions of HDA case temperatures above 122°F (50°C) or below 41°F ( 5°C) may occur with ou t impact to the
specified AFR. Continual or sustained operation at HDA case temperatures outside these limits may
degrade AFR.
Provided the HDA case temperatures limits are met, the drive meet s all specifications over a 41°F to 131°F
(5°C to 55°C) drive ambient temperature range with a maximum temperature gradient of 86°F (30°C) per
hour. Air flow may be needed in the drive enclosure to keep within this range (see Section 8. 3). Ope ration
at HDA case temperatures outside this range may adversely affect the drives ability to meet specifications.
To confirm that the required cooling for the electronics and HDA case is provided , place th e drive in its final
mechanical configuration, perform random write/read operations and measure the HDA case temperature
after it has stabilized.
-
Cheetah 15K.7 SAS Product Manual, Rev. D 29
Page 36
b. Non-operating
–40° to 158°F (–40° to 70°C) package ambient with a maximum gradient of 86°F (30°C) per hour. This
specification assumes that the drive is packaged in the shipping cont ainer designe d by Seagate for use with
drive.
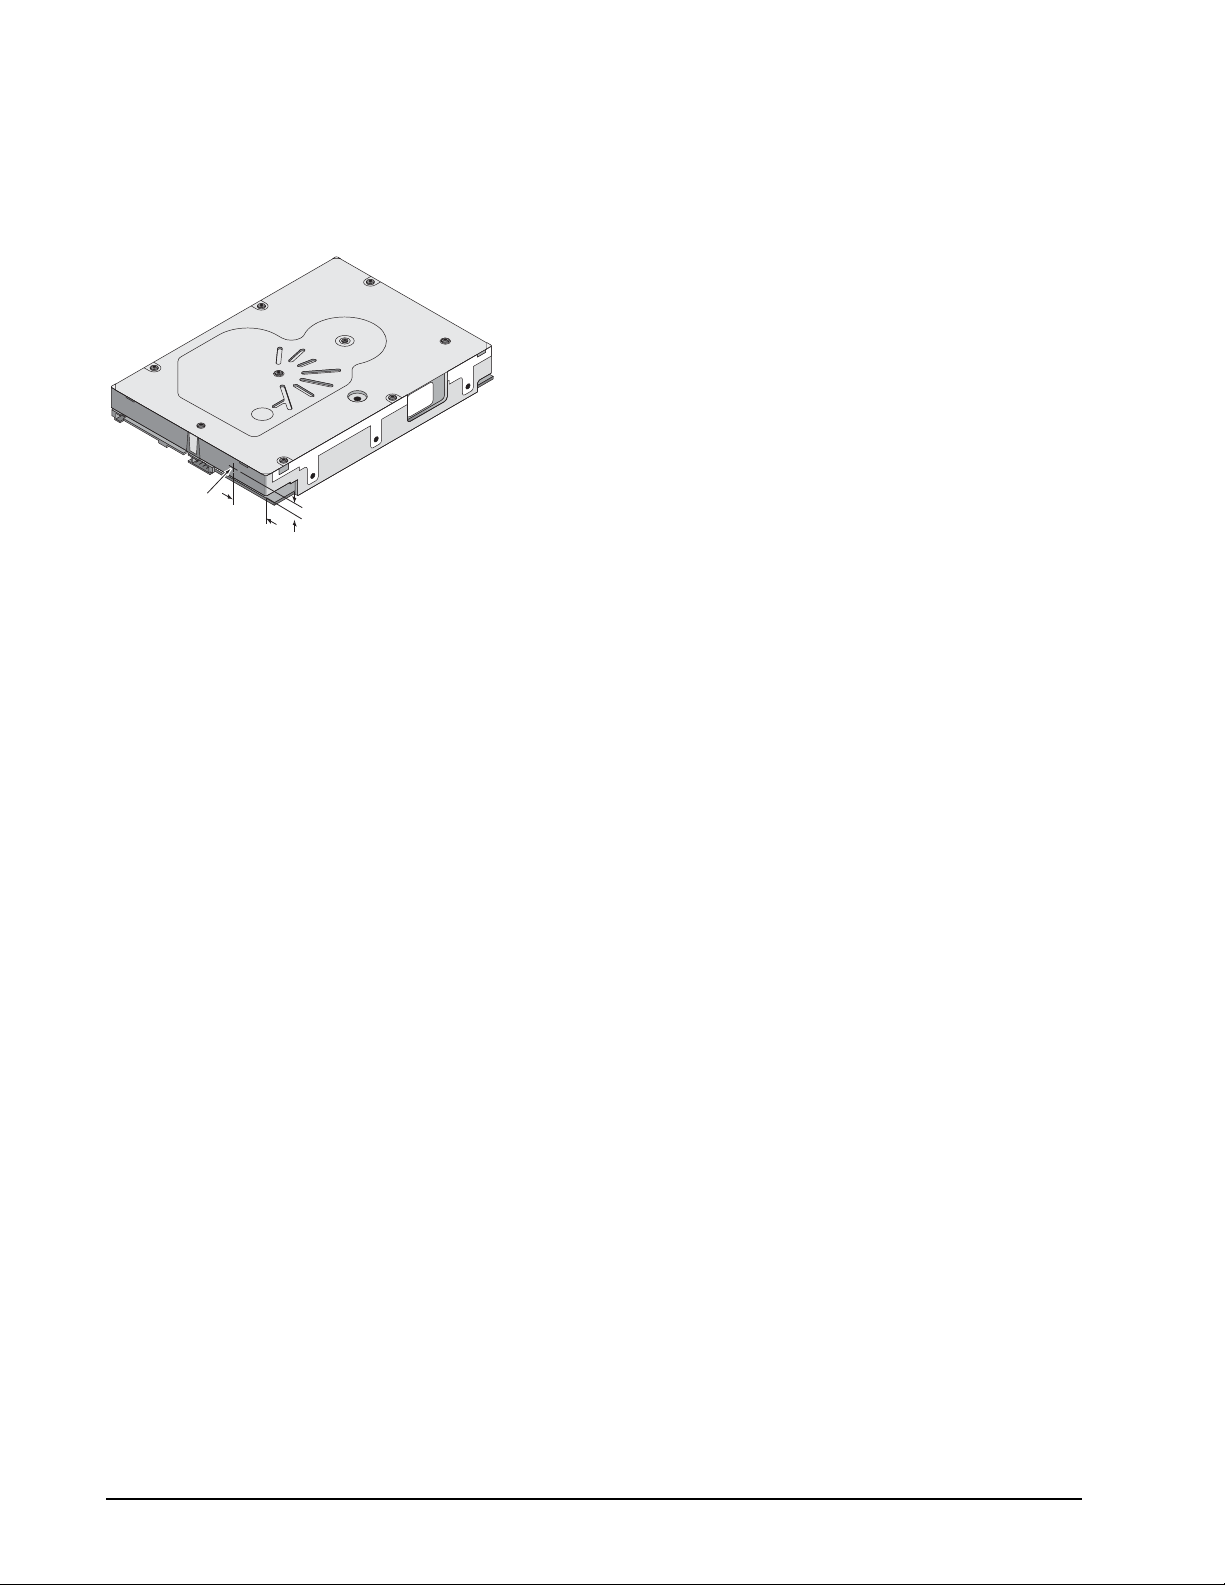
HDA Temp.
Check Point
Figure 7. Location of the HDA temperature check point
1.0"
.5"
7.4.2 Relative humidity
The values below assume that no condensation on the drive occurs.
a. Operating
5% to 95% non-condensing relative humidity with a maximum gradient of 20% per hour.
b. Non-operating
5% to 95% non-condensing relative humidity.
7.4.3 Effective altitude (sea level)
a. Operating
–1,000 to +10,000 feet (–305 to +3,048 meters)
b. Non-operating
–1,000 to +40,000 feet (–305 to +12,210 meters)
7.4.4 Shock and vibration
Shock and vibration limits specified in this document are measured direc tly on the drive chassis. If the drive is
installed in an enclosure to which the stated shock and/or vibration criteria is applied, resona nces may occur
internally to the enclosure resulting in drive movement in excess of the stated limits. If this situation is apparent,
it may be necessary to modify the enclosure to minimize drive movement.
The limits of shock and vibration defined within this document are specified with the drive mounted by any of
the four methods shown in Figure 8, and in accordance with the restrictions of Section 11.3.
7.4.4.1 Shock
a. Operating—normal
The drive, as installed for normal operation, shall oper ate error free while subjected to intermittent shock not
exceeding:
• 15 Gs at a duration of 11 msec (half sinewave)
• 20 Gs at a duration of 2 msec (half sinewave)
• 60 Gs at a duration of 2 msec (half sinewave) when performing reads only
30 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 37
Shock may be applied in the X, Y, or Z axis. Shock is not to be repeated more than once every 2 seconds.
b. Operating—abnormal
Equipment, as installed for normal operation, does not incur physical damage while subjected to intermittent shock not exceeding 40 Gs at a duration of 11 msec (half sinewave). Shock occurring at abnormal levels may promote degraded operational performance during the abnormal shock period. Specified
operational performance will continue when normal operating shock levels resume. Shock may be applied
in the X, Y, or Z axis. Shock is not to be repeated more than once every 2 seconds.
c. Non-operating
The limits of non-operating shock shall apply to all conditions of handling and transportation. This includes
both isolated drives and integrated drives.
The drive subjected to nonrepetitive shock not exceeding the three values below, shall not exhibit device
damage or performance degradation.
• 80 Gs at a duration of 11 msec (half sinewave)
• 300 Gs at a duration of 2 msec (half sinewave)
• 150 Gs at a duration of 0.5 msec (half sinewave)
Shock may be applied in the X, Y, or Z axis.
d. Packaged
disk drives shipped as loose load (not palletized) general freight will be packaged to withstand drops from
heights as defined in the table below. For additional details refer to Seagate specifications 30190-001
(under 100 lbs/45 kg) or 30191-001 (over 100 lbs/45 Kg).
Package size Packaged/product weight Drop height
<600 cu in (<9,800 cu cm) Any 60 in (1524 mm)
600-1800 cu in (9,800-19,700 cu cm) 0-20 lb (0 to 9.1 kg) 48 in (1219 mm)
>1800 cu in (>19,700 cu cm) 0-20 lb (0 to 9.1 kg) 42 in (1067 mm)
>600 cu in (>9,800 cu cm) 20-40 lb (9.1 to 18.1 kg) 36 in (914 mm)
Drives packaged in single or multipacks with a gross weight of 20 pounds (8.95 kg) or less by Seagate for
general freight shipment shall withstand a drop test from 48 inches (1,070 mm) against a concrete floor or
equivalent.
Cheetah 15K.7 SAS Product Manual, Rev. D 31
Page 38
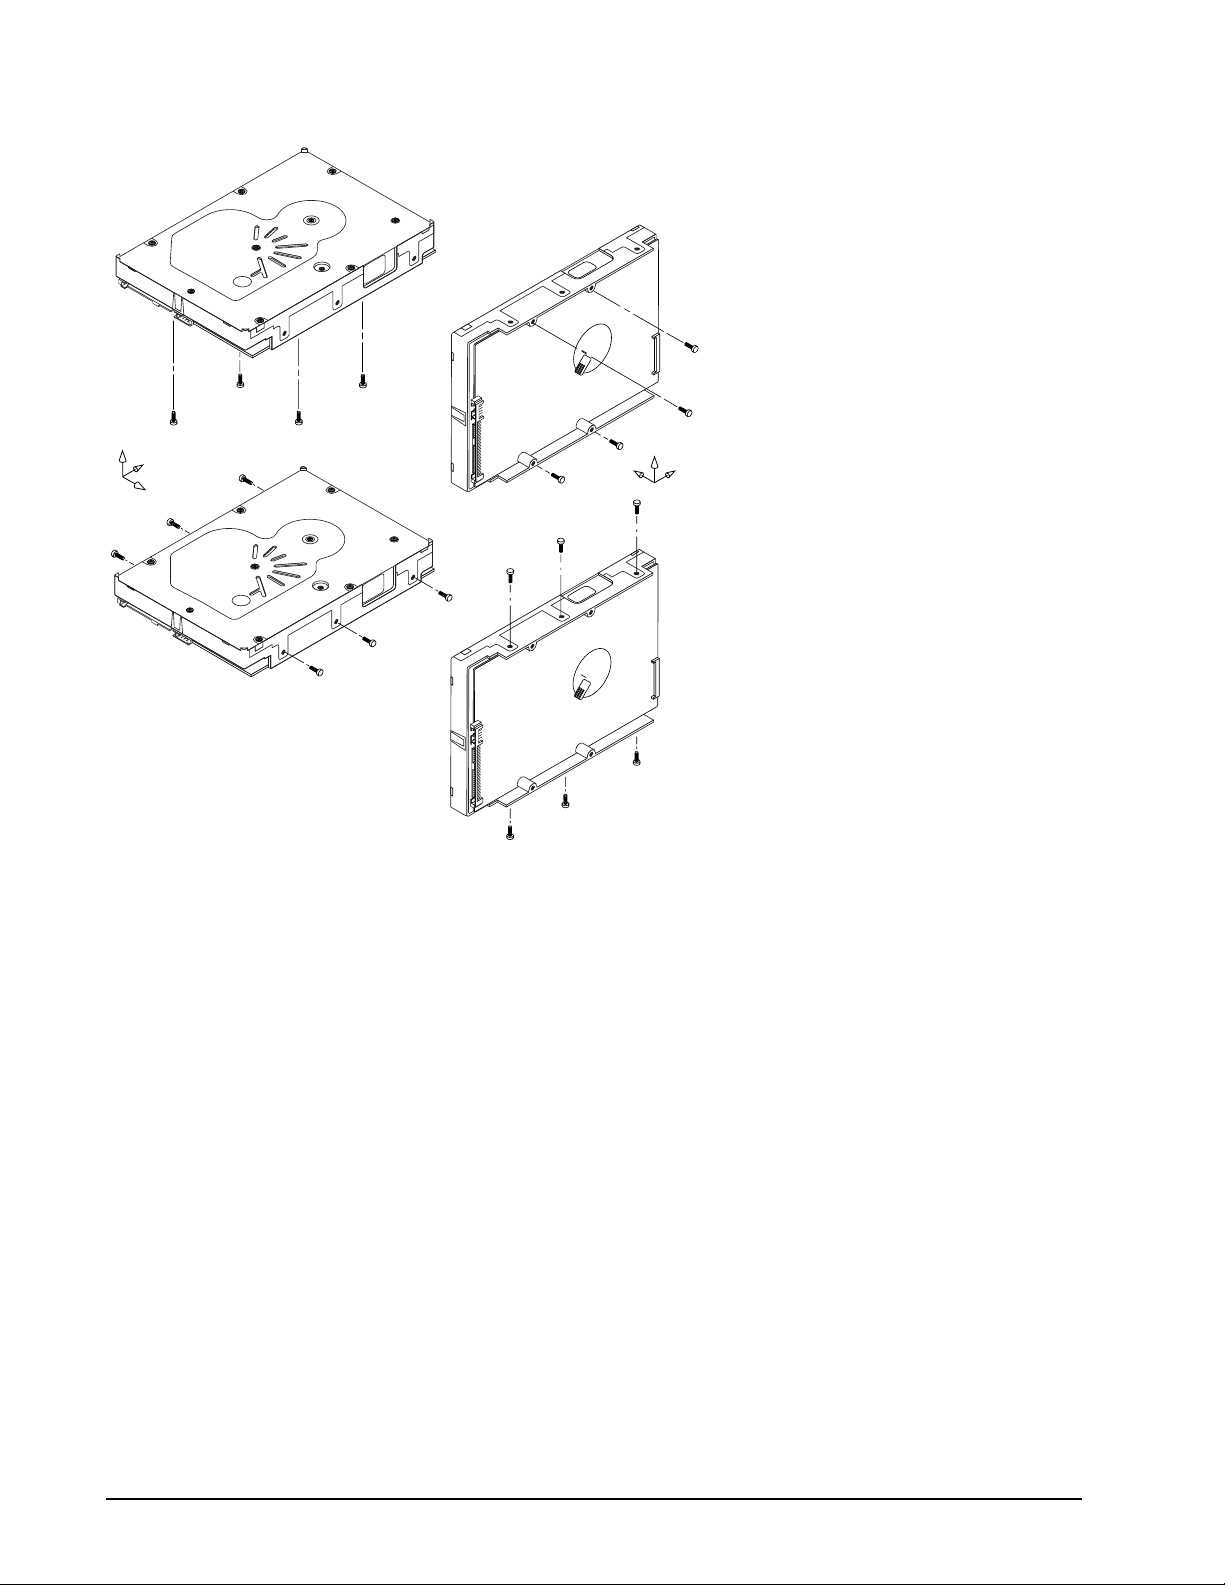
Z
Y
X
Figure 8. Recommended mounting
X
Y
Z
7.4.4.2 Vibration
a. Operating—normal
The drive as installed for normal operation, shall comply with the complete specified performance while
subjected to continuous vibration not exceeding
10 – 300 Hz 1.0 G RMS (0 to peak)
301– 500 Hz 0.5 G RMS (0 to peak)
Vibration may be applied in the X, Y, or Z axis.
b. Operating—abnormal
Equipment as installed for normal operation shall not incur physical damage while subjected to periodic
vibration not exceeding:
15 minutes of duration at major resonant frequency
Vibration occurring at these levels may degrade operational performance during the abnormal vibration
period. Specified operational performance will continue when normal operating vibration levels are
resumed. This assumes system recovery routines are available.
Operating abnormal translational random flat profile
5 – 500 Hz 0.75 G (0 to peak)
10 - 300 Hz 0.0029 G2/Hz
32 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 39
c. Non-operating
The limits of non-operating vibration shall apply to all conditions of handling and transportation. This
includes both isolated drives and integrated drives.
The drive shall not incur physical damage or degraded performance as a result of continuous vibration not
exceeding
5 – 22 Hz 0.25 G (0 to peak, linear, swept sine, 0.5 octive/min)
22 - 350 Hz 3 G (0 to peak, linear, swept sine, 0.5 octive/min)
350 - 500 Hz 1 G (0 to peak, linear, swept sine, 0.5 octive/min)
Vibration may be applied in the X, Y, or Z axis.
7.4.5 Acoustics
Sound power during idle mode shall be 3.4 bels typical when measured to ISO 7779 specification. Sound
power while operating shall be 3.8 bels typical when measured to ISO 7779 specification.
There will not be any discrete tones more than 10 dB above the masking noise on typical drives when measured according to Seagate specification 30553-001. There will not be any tones more than 24 dB above the
masking noise on any drive.
7.4.6 Air cleanliness
The drive is designed to operate in a typical office environment with minimal environmental control.
7.4.7 Corrosive environment
Seagate electronic drive components pass accelerated corrosion testing equivalent to 10 years exposure to
light industrial environments containing sulfurous gases, chlorine and nitric oxide, classes G and H per ASTM
B845. However, this accelerated testing cannot duplicate every potential application environment.
Users should use caution exposin g any electronic c omponents to uncontrolled chemical pollutants and corrosive chemicals as electronic drive component reliability can be affected by the installation environment. The silver, copper, nickel and gold films used in Seagate products are especially sensitive to the presence of sulfide,
chloride, and nitrate contaminants. Sulfur is found to be the most da maging. In addi tion, electronic comp onent s
should never be exposed to condensing water on the surface of the printed circuit board assembly (PCBA) or
exposed to an ambient relative humidity greater than 95%. Materials used in cabinet fabrication, such as vulcanized rubber, that can outgas corrosive compounds should be minimized or eliminated. The useful life of any
electronic equipment may be extended by replacing materials near circuitry with sulfide-free alternatives.
7.4.8 RoHS compliance statement
The European Union Restriction of Hazardous Substances (RoHS) Directive restricts the presence of chemical
substances, including Lead (Pb), in electronic products effective July 2006.
A number of parts and materials in Seagat e products are procured from external suppliers. We rely on the
representations of our suppliers regarding the presence of RoHS sub stances in these parts and materials. Our
supplier contracts require compliance with our che mical substance restrictions, and our suppliers document
their compliance with our requirements by providing material conten t declarations for all p arts and materials for
the disc drives documented in this publication. Current supplier declarations include disclosure of the inclusion
of any RoHS-regulated substance in such parts or materials.
Seagate also has internal systems in place to ensure on going compliance with the RoHS Directive and all laws
and regulations which restrict chemical content in electronic products. These systems include standard operating procedures that ensure that restricted substances are not utilized in our manufacturing operations, laboratory analytical validation testing, and an internal auditing process to ensure that we comply with all standard
operating procedures.
Cheetah 15K.7 SAS Product Manual, Rev. D 33
Page 40
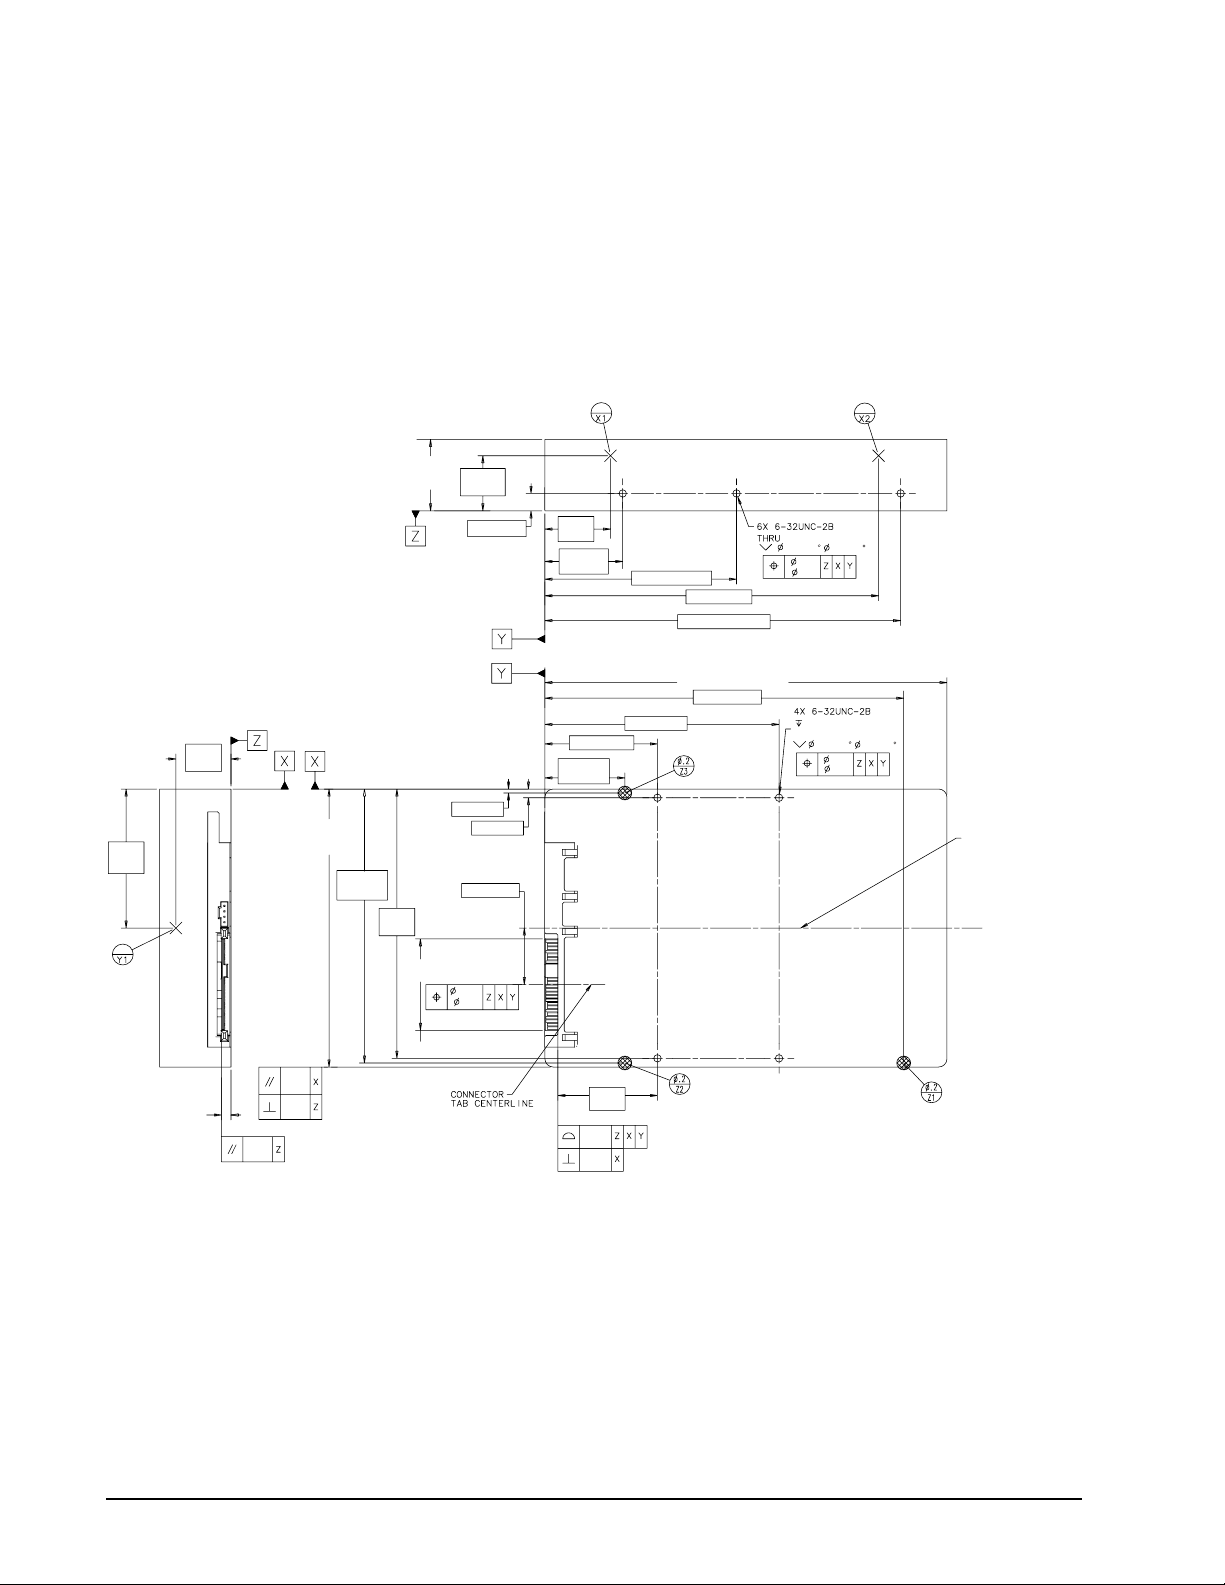
7.4.9 Electromagnetic susceptibility
See Section 3.1.1.1.
7.5 Mechanical specifications
Refer to Figure 9 for detailed physical dimensions. See Section 11.3, “Drive mounting.”
Height: 1.03 in 26.10 mm
Width: 4.00 in 101.60 mm
Depth: 5.79 in 147 mm
Weight (max): 1.76 pounds 0.80 kilograms
50.80
(2.000)
UNITS OF MEASURE: mm (inches)
20.14
(.793)
101.60 +/- .25
(4.000 +/- .010)
2X 100.13
(2X 3.942)
26.11 MAX
(1.028 MAX)
98.42
(3.875)
33.40
(1.315)
2X 20.14
(2X .793)
1.45 (.057)
20.68 (.814)
0.76
( .030)
6.35 (.250)
3.17 (.125)
24.00
(.945)
2X 28.45
(2X 1.120)
41.15 (1.620)
2X 29.21
(2X 1.150)
2X 70.05 (2X 2.758)
2X 130.05 (2X 5.120)
85.60 (3.370)
122.00 (4.803)
146.99 MAX (5.787 MAX)
131.17 (5.164)
4.22 X 90 ( .166 X 90 )
0.36
( .014)
4.57 MIN BLIND
( .18 MIN BLIND)
4.22 X 90 ( .166 X 90 )
0.36
( .014)
DRIVE
CENTER
LINE
0.13
3.50 +/- .38
(.138 +/- .015)
0.25
(.010)
(.005)
0.13
(.005)
0.99
(.039)
0.41
(.016)
36.37
(1.432)
Figure 9. Physical dimensions
34 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 41
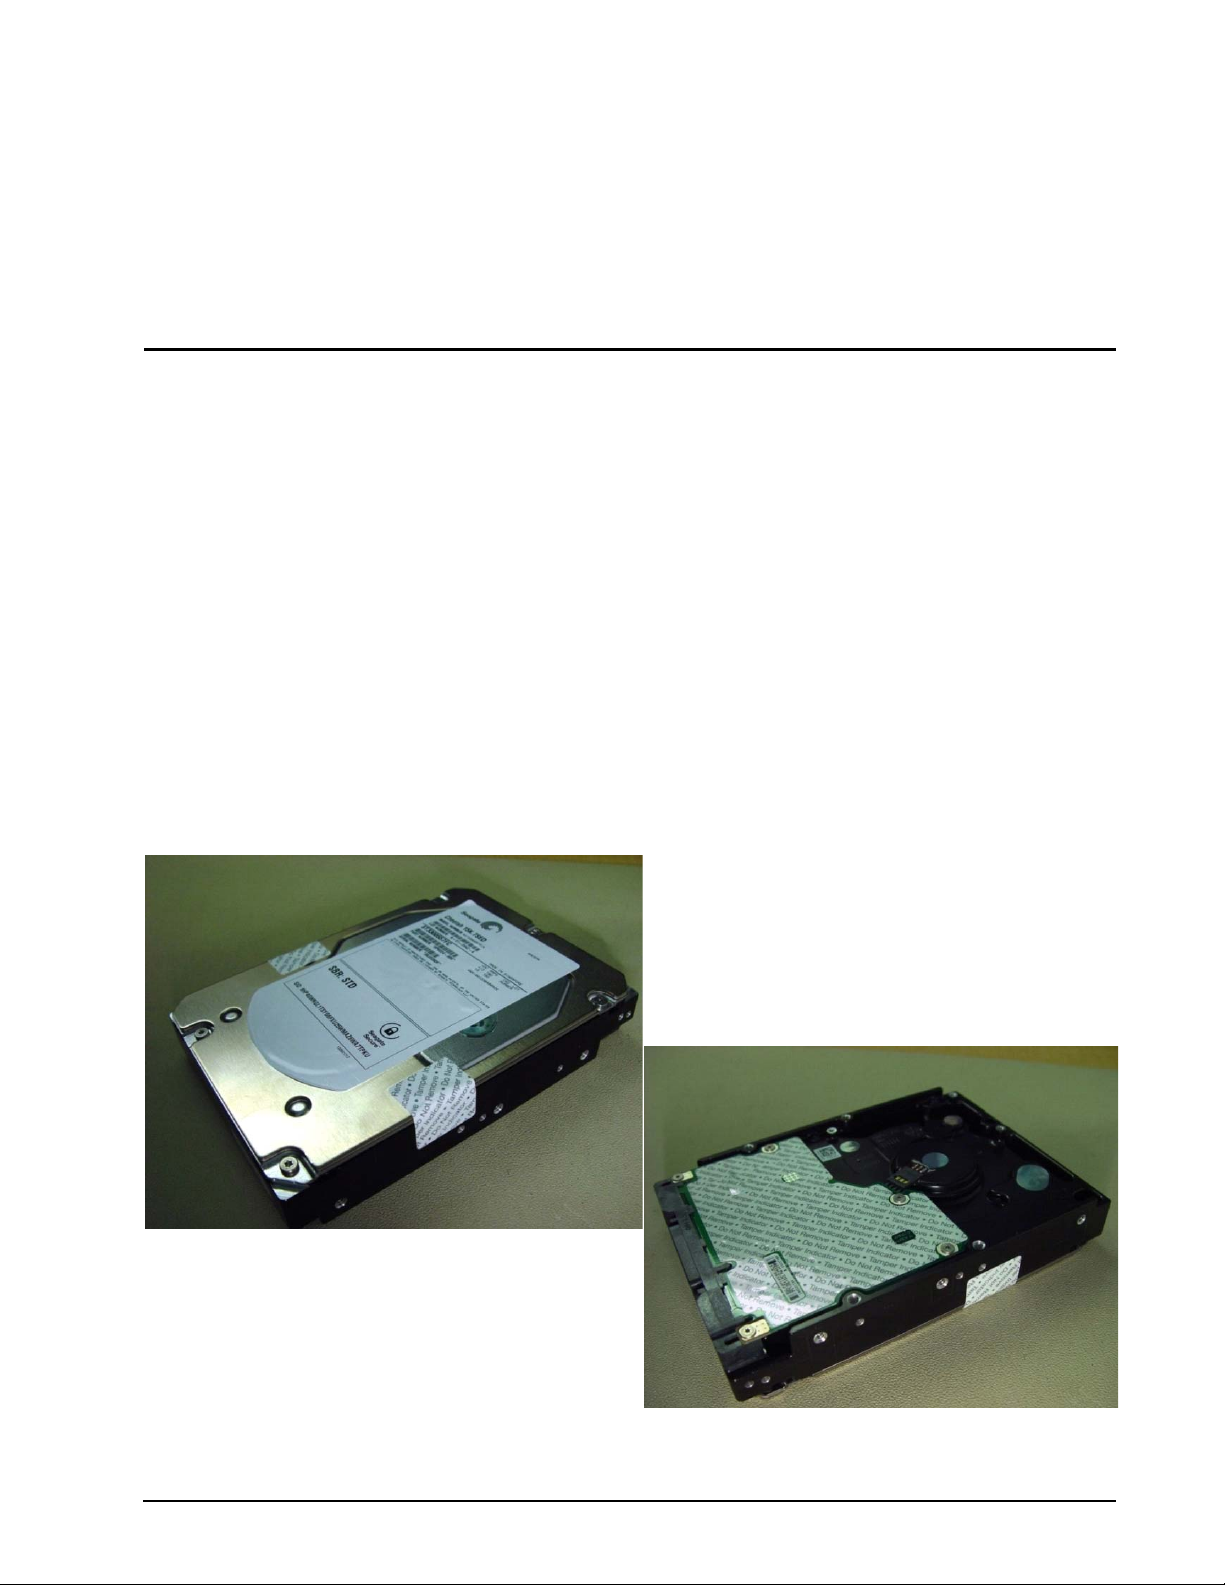
8.0 About FIPS
The Federal Information Processing Standard (FIPS) Publication 140-2, FIPS PUB 140-2, is a U.S. government computer security standard used to accredit crypto gr aphic modules. It is titled “Security Requiremen ts for
Cryptographic Modules”. The initial publicat ion was o n M ay 25, 2 001 a nd was la st upd ated Decemb er 3, 2002.
Purpose
The National Institute of Standards and Technology (NIST) issued the FIPS 140 Publicatio n Series to coordinate the requirements and standards for cryptography modules that include both hardware and software components.
Federal Information Processing Standard (FIPS) 140-2 Level 2 Certification requires drives to go through government agencies certifications to add requirements for physical tamper-evidence and role-based authentication.
Level 2 security
Level 2 improves upon the physical security mechanisms of a Level 1 (lowest level of security) cryptographic
module by requiring features that show evidence of tampering, including tamper-evident coatings or seals that
must be broken to attain physical access to th e plaintext cryptographic keys and critic al security parameters
(CSPs) within the module, or pick-resistant locks on covers or doors to protect against unauthorized physical
access.
Figure 10. Example of FIPS tamper evidence labels. Does not represent actual drive.
Cheetah 15K.7 SAS Product Manual, Rev. D 35
Page 42
9.0 About self-encrypting drives
Self-encrypting drives (SEDs) offer encryption and security services for the protection of stored data, commonly known as “protection of data at rest.” These drives are compliant with the Trusted Computing Group
(TCG) Enterprise Storage Specifications as detailed in Section 3.4.
The Trusted Computing Group (TCG) is an organization sponsored and operated by companies in the computer, storage and digital communications industry. Seagate’s SED models comply with the standards published by the TCG.
To use the security features in the drive, the host must be capable of constructing and issuing th e following two
SCSI commands:
• Security Protocol Out
• Security Protocol In
These commands are used to convey the TCG protocol to and from the drive in their command payloads.
9.1 Data encryption
Encrypting drives use one inline encryption engine for each port, emp loying AES-128 dat a encryption in Cipher
Block Chaining (CBC) mode to encrypt all data prior to being written on the media and to decrypt all data as it
is read from the media. The encryption engines are always in operation, cannot be disabled, and do not d etract
in any way from the performance of the drive.
The 32-byte Data Encryption Key (DEK) is a random number which is genera ted by the dr ive, never leaves the
drive, and is inaccessible to the host system. The DEK is itself encrypted when it is stored on the media and
when it is in volatile temporary storage (DRAM) external to the encryption engine. A unique data encryption
key is used for each of the drive's possible16 data bands (see Section 9.5).
9.2 Controlled access
The drive has two security partitions (SPs) called the "Admin SP" and the "Locking SP." These act as gatekeepers to the drive security services. Security-related commands will not be accepted unless they also supply
the correct credentials to prove the requester is authorized to perform the command.
9.2.1 Admin SP
The Admin SP allows the drive's owner to enable or disable firmware download operations (see Section 9.4).
Access to the Admin SP is available using the SID (Secure ID) password or the MSID (Makers Secure ID)
password.
9.2.2 Locking SP
The Locking SP controls read/write access to the media and the cryptographic erase feature. Access to the
Locking SP is available using the BandMasterX or EraseMaster passwords. Since the drive owner can define
up to 16 data bands on the drive, each data band has its own password called BandMasterX where X is the
number of the data band (0 through 15).
36 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 43
9.2.3 Default password
When the drive is shipped from the factory, all passwords are set to the value of MSID. This 32-byte random
value is printed on the drive label and it can be read by the host electronically over the I/O. After receipt of the
drive, it is the responsibility of the owner to use the default MSID password as the authority to change all other
passwords to unique owner-specified values.
9.3 Random number generator (RNG)
The drive has a 32-byte hardware RNG that it is uses to derive encryption keys or, if requested to do so, to provide random numbers to the host for system use, including using these nu mbers as Authentication Keys ( p asswords) for the drive’s Admin and Locking SPs.
9.4 Drive locking
In addition to changing the passwords, as described in Section 9.2.3, the owner should also set the data
access controls for the individual bands.
The variable "LockOnReset" should be set to "PowerCycle" to ensure that the data bands will be locked if
power is lost. This scenario occurs if the drive is removed from its cabinet. The drive will not honor any data
read or write requests until the bands have been unlocked. This prevents the user data from being accessed
without the appropriate credentials when the drive has been removed from its cabinet and installed in another
system.
When the drive is shipped from the factory, the firmware download port is locked and the drive will reject any
attempt to download new firmware. Th e dr ive own er m ust us e th e SID cr ed en tia l to un loc k th e fir m wa re do wn load port before firmware updates will be accepted.
9.5 Data bands
When shipped from the factory, the drive is configured with a single data band called Band 0 (als o known as
the Global Data Band) which comprises LBA 0 through LBA max. The host may allocate Band1 by specifying a
start LBA and an LBA range. The r eal est a te for this band is t aken from the Global Band. An add itional 14 Dat a
Bands may be defined in a similar way (Band2 through Band15) but before these bands can be allocated LBA
space, they must first be individually enabled using the EraseMaster password.
Data bands cannot overlap but they can be sequential with one ba nd e ndi ng at LBA (x) and the ne xt b eginnin g
at LBA (x+1).
Each data band has its own drive-generate d encryption key and it s own user-supplied p assword. The host may
change the Encryption Key (see Section 9.6) or the password when required. The bands should be aligned to
4K LBA boundaries.
9.6 Cryptographic erase
A significant feature of SEDs is the ability to perform a cryptographic erase. This involves the host telling the
drive to change the data encryption key for a p ar ticu lar ban d. On ce chang ed , the data is no longer recoverable
since it was written with one key and will be read using a different key. Since the drive overwrites the old key
with the new one, and keeps no history of key changes, the user data can never be recovered. This is tantamount to an instantaneous data erase and is very useful if the drive is to be scrapped or redispositioned.
9.7 Authenticated firmware download
In addition to providing a locking mechanism to prevent unwanted firmware download attempts, the drive also
only accepts download files which have been cryptographically signed by the appropriate Seagate Design
Center.
Three conditions must be met before the drive will allow the download operation:
1. The download must be an SED file. A standard (base) drive (non-SED) file will be rejected.
Cheetah 15K.7 SAS Product Manual, Rev. D 37
Page 44
2. The download file must be signed and authenticated.
3. As with a non-SED drive, the download file must pass the acceptance criteria for the drive. For example it
must be applicable to the correct drive model, and have compatible revision and customer status.
9.8 Power requirements
The standard drive models and the SED drive models have identical hardware, however the security and
encryption portion of the drive controller ASIC is enabled and functional in the SED models. This represents a
small additional drain on the 5V supply of about 30mA and a commensurate increase of about 150mW in
power consumption. There is no additiona l drain on the 12V supply. See the tables in Section 7.2 for power
requirements on the standard (non-SED) drive models.
9.9 Supported commands
The SED models support the following two commands in addition to the commands supported by the standard
(non-SED) models as listed in Table 20:
• Security Protocol Out (B5h)
• Security Protocol In (A2h)
38 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 45
10.0 Defect and error management
Seagate continues to use innovative technologies to manage defects and errors. These technologies are
designed to increase data integrity, perform drive self-maintenance, and validate proper drive operation.
SCSI defect and error managemen t involves drive internal defect/error management and SAS system error
considerations (errors in communications between the initiator and the drive). In addition, Seagate provides
the following technologies used to increase data integrity and drive reliability:
• Background Media Scan (see Section 10.4)
• Media Pre-Scan (see Section 10.5)
• Deferred Auto-Reallocation (see Section 10.6)
• Idle Read After Write (see Section 10.7)
The read error rates and specified storage capacities are not dependent on host (initiator) defect management
routines.
10.1 Drive internal defects/errors
During the initial drive format operation at the factory, media defects are identified, tagged as being unusable,
and their locations recorded on the drive primary defects list (referred to as the “P’ list and also as the ETF
defect list). At factory format time, these known defects are also reallocated, that is, reassigned to a new place
on the medium and the location liste d in the defects reallocation table. The “P” list is not altered after factory
formatting. Locations of defects found and reallocated during error recovery procedures after drive shipment
are listed in the “G” list (defects growth list). The “P” and “G” lists may be referenced by the initiator using the
Read Defect Data command.
Details of the SCSI commands supported by the drive are described in the SAS Interface Manual. Also, more
information on the drive Error Recovery philosophy is presented in the SAS Interface Manual.
10.2 Drive error recovery procedures
When an error occurs during drive operation, the drive, if pr ogrammed to do so, performs e rror recover y procedures to attempt to recover the dat a . The erro r reco very pro cedures us ed depen d on the o ptions prev iously set
in the Error Recovery Parameters mode page. Error recovery and defect management may involve using several SCSI commands described in the SAS Interface Manual. The drive implements selectable error recovery
time limits required in video applications.
The error recovery scheme supported by the drive provides a way to control the to tal error r ecovery time for the
entire command in addition to controlling the recovery level for a single LBA. The total amount of time spent in
error recovery for a command can be limited using the Recovery Time Limit bytes in the Error Recovery mode
page. The total amount of time spent in error recovery for a single LBA can be limited using the Read Retry
Count or Write Retry Count bytes in the Error Recovery mode page.
The drive firmware error recovery algorithms consists of 13 levels for read recoveries and five levels for write.
Each level may consist of multiple steps, where a step is defined as a recovery function involving a single reread or re-write attempt. The maximum level used by the drive in LBA recovery is determined by the read and
write retry counts.
Cheetah 15K.7 SAS Product Manual, Rev. D 39
Page 46
Table 17 equates the read and write retry count with the maximum possible recovery time for read and write
recovery of individual LBAs. The times given do not include time taken to perform reallocations. Reallocations
are performed when the ARRE bit (for reads) or AWRE bit (for writes) is one, the RC bit is zero, and the recovery time limit for the command has not yet been met. Time needed to perform reallocation is not counted
against the recovery time limit.
When the RC bit is one, reallocations are disabled even if the ARRE or AWRE bits are one. The drive will still
perform data recovery actions within the limits defined by the Read Retry Count, Write Retry Count, and
Recovery Time Limit parameters. However, the drive does not report any unrecovered errors
40 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 47
Table 17: Read and write retry count maximum recovery times [1]
Read retry
count
0 51.87 0 23.94
1 59.85 1 35.91
2 203.49 2 39.9
3 231.42 3 51.87
4 295.26 4 79.8
5 327.18 5 (default) 107.73
6359.10
7446.88
8538.65
9570.57
10 598.50
11 (default) 1,534.97
Maximum recovery time per LBA
(cumulative, msec)
Write retry
count
Maximum recovery time per LBA
(cumulative, msec)
[1] These values are subject to change.
Setting these retry counts to a value below the default setting could result in degradation of the unrecovered error rate which may exceed the value given in this product manual. A setting of zero (0) will result in
the drive not performing error recovery.
For example, suppose the read/write recovery page has the RC bit set to 0, read retry count set to 4, and
the recovery time limit field (Mode Sense page 01, bytes 10 and 11) set to FF FF hex (maximum). A four
LBA Read command is allowed to take up to 253.11 msec recovery time for each of the four LBAs in the
command. If the recovery time limit is set to 00 C8 hex (200 msec decimal) a four LBA read command is
allowed to take up to 200 msec for all error recovery within that command. The use of the Recovery Time
Limit field allows finer granularity on control of the time spent in error recovery. The recovery time limit
only starts counting when the drive is executing error recovery and it restarts on each command. There
fore, each command’s total recovery time is subject to the recovery time limit. Note: A recovery time limit
of 0 will use the drive’s default value of FF FF. Minimum recovery time limit is achieved by setting the
Recovery Time Limit field to 00 01.
-
10.3 SAS system errors
Information on the reporting of operational errors or faults across the interface is given in the SAS Interface
Manual. The SSP Response returns information to the host about numerous kinds of errors or faults. The
Receive Diagnostic Results reports the results of diagnostic operations performed by the drive.
Status returned by the drive to the initiator is described in the SAS Interface Manual. Status reporting plays a
role in systems error management and its use in that respect is described in sections where the various commands are discussed.
10.4 Background Media Scan
Background Media Scan (BMS) is a self-initiated media scan. BMS is defined in the T10 document SPC-4
available from the T10 committee. BMS performs sequential reads across the entire pack of the media while
the drive is idle. In RAID arrays, BMS allows hot spare drives to be scann ed for defects prior to being pu t into
service by the host system. On regular duty drives, if the host system makes use of the BMS Log Page, it can
avoid placing data in suspect locations on the media. Unreadable and recovered error sites will be logged or
reallocated per ARRE/AWRE settings.
Cheetah 15K.7 SAS Product Manual, Rev. D 41
Page 48
With BMS, the host system can consume less power and system overhead by only checking BMS status and
results rather than tying up the bus and consuming power in the process of host-i nitiated media scan ning activity.
Since the background scan functions are only done dur ing idle periods, BMS ca uses a negligible imp act to system performance. The first BMS scan for a newly manufactured drive is performed as quickly as possible to
verify the media and protect data by setting the “Start time after idle” to 5ms, all subsequent scans begin after
500ms of idle time. Other features that normally use idle time to function will function normally because BMS
functions for bursts of 800ms and then suspends activity for 100ms to allow other background functions to
operate.
BMS interrupts immediately to service host commands from the interface bus while performing reads. BMS will
complete any BMS-initiated error recovery prior to returning to service host-initiated commands. Overhead
associated with a return to host-s ervicing activity from BMS only impacts the first command that interrupted
BMS, this results in a typical delay of about 1 ms.
10.5 Media Pre-Scan
Media Pre-Scan is a feature that allows the drive to repair media errors that would otherwise have been found
by the host system during critical data accesses early in the drive’s life. The default setting for Media Pre-Scan
is enabled on standard products. Media Pre-Scan checks each write command to determine if the destination
LBAs have been scanned by BMS. If the LBAs have been verified, the drive proceeds with the normal write
command. If the LBAs have not been verified by BMS, Pre-Scan will convert the write to a write verify to certify
that the data was properly written to the disk.
Note. During Pre-Scan write verify commands, write performance may decrease by 50% until Pre-Scan
completes. Write performance testing should be performed after Pre-Sca n is complete. This may
be checked by reading the BMS status.
To expedite the scan of the full pack and subsequently exit from the Pre-Scan period, BMS will begin scanning
immediately when the drive goes to idle during the Pre-Scan period. In the event that the drive is in a high
transaction traffic environment and is unable to complete a BMS scan within 24 power on hours BMS will disable Pre-Scan to restore full performance to the system.
10.6 Deferred Auto-Reallocation
Deferred Auto-Reallocation (DAR) simplifies reallocation algorithms at the system level by allowing the drive to
reallocate unreadable locations on a subsequent write command. Sites are marked for DAR during read operations performed by the drive. When a write command is received for an LBA marked for DAR, the auto-reallocation process is invoked and attempts to rewrite the data to the original location. If a verification of this rewrite
fails, the sector is re-mapped to a spare location.
This is in contrast to the system having to use the Reassign Command to reassign a location that was unreadable and then generate a write command to rewrite the data. DAR is most effective when AWRE and ARRE
are enabled—this is the default setting from the Seagate factory. With AWRE and ARRE disabled DAR is
unable to reallocate the failing location and will report an error sense code indicating that a write command is
being attempted to a previously failing location.
10.7 Idle Read After Write
Idle Read After Write (IRAW) utilizes idle time to verify the integrity of recently written data. During idle periods,
no active system requests, the drive reads recently written data from the media and compares it to valid write
command data resident in the drives data buffer. Any sectors that fail the comparison result in the invocation of
a rewrite and auto-reallocation process. The process attempts to rewrite the data to the original location. If a
verification of this rewrite fails, the sector is re-mapped to a spare location.
42 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 49
11.0 Installation
Cheetah 15K.7 disk drive installation is a plug-and-play process. There are no jumpers, s witches, or termina tors on the drive.
SAS drives are designed to be used in a host system that provides a SAS-compatible backplane with bays
designed to accommodate the drive. In such systems, the host system typically provides a carrier or tray into
which you need to mount the drive. Mount the drive to th e carrier o r tray provided by the host system using four
6-32 UNC screws. Do not over-tighten or force the screws. You can mount the drive in any orientation.
Note. SAS drives are designed to be attached to the host system without I/O or power cables. If you
intend the use the drive in a non-backplane host system, connecting the drive using high-quality
cables is acceptable as long as the I/O cable length does not exceed 4 meters (13.1 feet).
Slide the carrier or tray into the appropriate bay in your host system using the instructions provided by the host
system. This connects the drive directly to your system’s SAS connector. The SAS connector is normally
located on a SAS backpanel. See Section 12.4.1 for additional information about these connectors.
Power is supplied through the SAS connector.
The drive is shipped from the factory low-level formatted in 512-byte logical blocks. You need to reformat the
drive only if you want to select a different logical block size.
11.1 Drive orientation
The drive may be mounted in any orientation. All drive performance characterizations, however, have been
done with the drive in horizontal (disks level) and vertical (drive on its side) orientations, which are the two preferred mounting orientations.
11.2 Cooling
Cabinet cooling must be designed by the customer so that the ambient temperature immediately surrounding
the drive will not exceed temperature conditions specified in Section 7.4.1, "Temperature."
The rack, cabinet, or drawer environment for the drive must provide heat removal from the electronics and
head and disk assembly (HDA). You should confirm that adequate heat removal is provided using the temperature measurement guidelines described in Section 7.4.1.
Forced air flow may be r equired to keep temper atures a t or be low the t emperat ures s pecified in Section 7.4.1
in which case the drive should be oriented, or air flow directed, so th at the least amount of air flow resistance is
created while providing air flow to the electronics an d HDA. Also, the shortest possible path between the air
inlet and exit should be chosen to minimize the travel length of air heated by the drive and other heat sources
within the rack, cabinet, or drawer environment.
Cheetah 15K.7 SAS Product Manual, Rev. D 43
Page 50
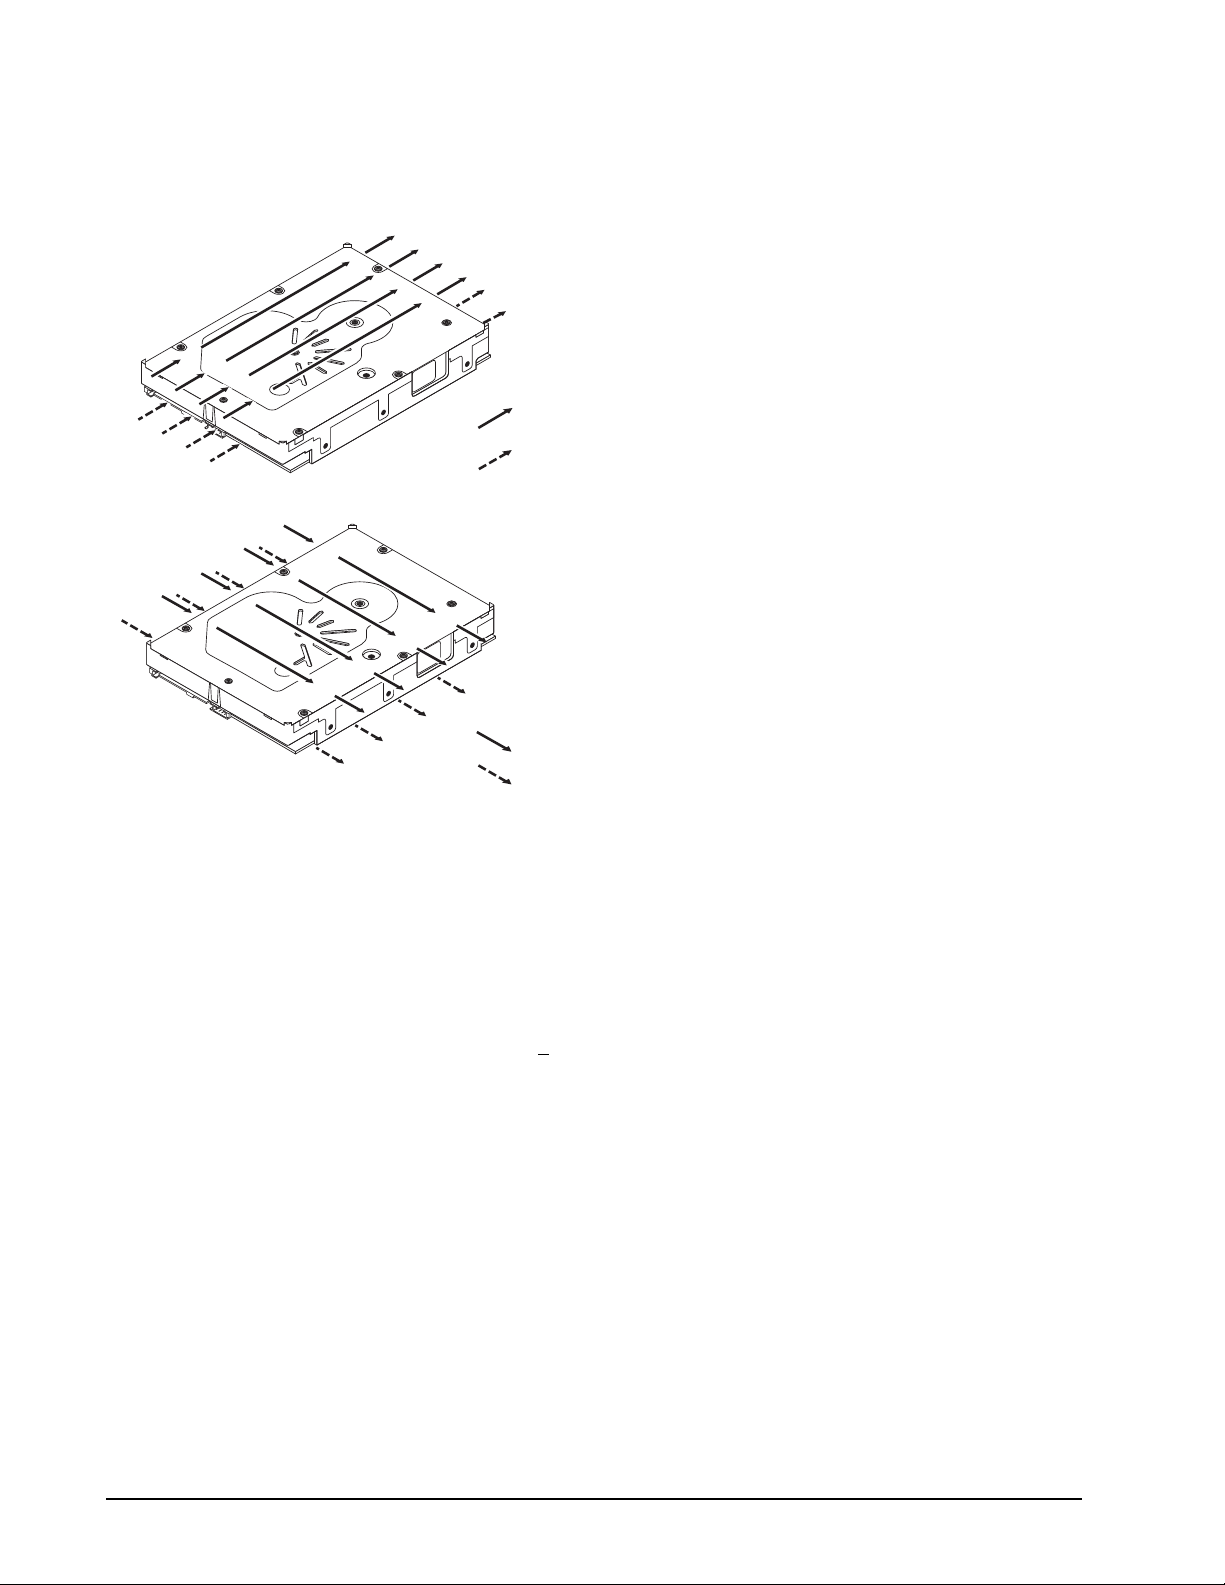
If forced air is determined to be necessary, possible air-flow patterns are shown in Figure 11. The air-flow patterns are created by one or more fans, either forcing or drawing air as shown in the illustrations. Conduction,
convection, or other forced air-flow patterns are acceptable as long as the temperature measurement guidelines of Section 7.4.1 are met.
Above unit
Note. Air flows in the direction shown (back to front)
or in reverse direction (front to back)
Note. Air flows in the direction shown or
in reverse direction (side to side)
Figure 11. Air flow
Under unit
Above unit
Under unit
11.3 Drive mounting
Mount the drive using the bottom or side mounting holes . If you mount the drive using the bottom holes, e nsure
that you do not physically distort the drive by attempting to mount it on a stiff, non-flat surface.
The allowable mounting surface stiffness is 80 lb/in (14.0 N/mm) . The followin g equation and paragraph define
the allowable mounting surface stiffness:
K x X = F < 15lb = 67N
where K is the mounting surface stiffness (units in lb/in or N/mm) and X is the out-of-plane surface distortion
(units in inches or millimeters). The out-of-plane distortion (X) is determined by defining a plane with three of
the four mounting points fixed and evaluating the out-of-plane deflection of the fourth mounting point when a
known force (F) is applied to the fourth point.
11.4 Grounding
Signal ground (PCBA) and HDA ground are connected together in the drive and cannot be separated by the
user. The equipment in which the drive is mounted is connected directly to the HDA and PCBA with no electrically isolating shock mounts. If it is desired for the system chassis to not be connected to the HDA/PCBA
ground, the systems integrator or user must provide a nonconductive (electrically isolating) method of mounting the drive in the host equipment.
Increased radiated emissions may result if you do not provide the maximum surface area ground connection
between system ground and drive ground. This is the system designer’s and integrator’s responsibility.
44 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 51
12.0 Interface requirements
This section partially describes the interface requirements as implemented on Cheetah 15K.7 drives. Additional information is provided in the SAS Interface Manual (part number 100293071).
12.1 SAS features
This section lists the SAS-specific features supported by Cheetah 15K.7 drives.
12.1.1 task management functions
Table 18 lists the SAS task management functions supported.
Table 18: SAS task management functions supported
Task name Supported
Abort Task Yes
Clear ACA Yes
Clear task set Yes
Abort task set Yes
Logical Unit Reset Yes
Query Task Yes
12.1.2 task management responses
Table 19 lists the SAS response codes returned for task management functions supported.
Table 19: Task management response codes
Function name Response co de
Function complete 00
Invalid frame 02
Function not supported 04
Function failed 05
Function succeeded 08
Invalid logical unit 09
Cheetah 15K.7 SAS Product Manual, Rev. D 45
Page 52
12.2 Dual port support
Cheetah 15K.7 SAS drives have two independent ports. These ports may be connected in the same or different SCSI domains. Each drive port has a unique SAS address.
The two ports have the capability of independent port clocking (e.g. both ports can run at 6Gbit/sec or the first
port can run at 6Gbit/sec while the second port runs at 3Gbit/sec.) The supported link rates are 1.5, 3.0, or 6.0
Gbits/sec.
Subject to buffer availability, the Cheetah 15K.7 drives support:
• Concurrent port transfers—The drive supports receiving COMMAND, TASK management transfers on both
ports at the same time.
Full duplex—The drive supports sending XFER_RDY, DATA and RESPONSE transfers while receiving frames
on both ports.
12.3 SCSI commands supported
Table 20 lists the SCSI commands supported by Cheetah 15K.7 drives.
Table 20: Commands supported by Cheetah 15K.6 SAS family driv es
Command name Command code Supported
Change Definition 40h N
Compare 39h N
Copy 18h N
Copy and Verify 3Ah N
Format Unit [1] 04h Y
DPRY bit supported N
DCRT bit supported Y
STPF bit supported Y
IP bit supported Y
DSP bit supported Y
IMMED bit supported Y
VS (vendor specific) N
Inquiry 12h Y
Date Code page (C1h) Y
Device Behavior page (C3h) Y
Firmware Numbers page (C0h) Y
Implemented Operating Def page (81h) Y
Jumper Settings page (C2h) Y
Supported Vital Product Data page (00h) Y
Unit Serial Number page (80h) Y
Lock-unlock cache 36h N
Log Select 4Ch Y
PCR bit Y
DU bit N
DS bit Y
46 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 53
Table 20: Commands supported by Cheetah 15K.6 SAS family drives (continued)
Command name Command code Supported
TSD bit Y
ETC bit N
TMC bit N
LP bit N
Log Sense 4Dh Y
Application Client Log page (0Fh) Y
Buffer Over-run/Under-run page (01h) N
Cache Statistics page (37h) Y
Factory Log page (3Eh) Y
Last n Deferred Errors or Asynchronous Events page (0Bh) N
Last n Error Events page (07h) N
Non-medium Error page (06h) Y
Pages Supported list (00h) Y
Read Error Counter page (03h) Y
Read Reverse Error Counter page (04h) N
Self-test Results page (10h) Y
Background Medium Scan page (15h) Y
Start-stop Cycle Counter page (0Eh) N
Temperature page (0Dh) Y
Verify Error Counter page (05h) Y
Write error counter page (02h) Y
Mode Select (same pages as Mode Sense 1Ah) 15h Y [2]
Mode Select (10) (same pages as Mode Sense 1Ah) 55h Y
Mode Sense 1Ah Y [2]
Caching Parameters page (08h) Y
Control Mode page (0Ah) Y
Disconnect/Reconnect (02h) Y
Error Recovery page (01h) Y
Format page (03h) Y
Information Exceptions Control page (1Ch) Y
Background Scan mode subpage (01h) Y
Notch and Partition Page (0Ch) N
Protocol-Specific Port page (19h) Y
Power Condition page (1Ah) Y
Rigid disk Drive Geometry page (04h) Y
Unit Attention page (00h) Y
Verify Error Recovery page (07h) Y
Xor Control page (10h) N
Cheetah 15K.7 SAS Product Manual, Rev. D 47
Page 54
Table 20: Commands supported by Cheetah 15K.6 SAS family driv es (continued)
Command name Command code Supported
Mode Sense (10) (same pages as Mode Sense 1Ah) 5Ah Y
Prefetch 34h N
Read 08h Y
Read Buffer (modes 0, 2, 3, Ah and Bh supported) 3Ch Y
Read Capacity 25h Y
Read Defect Data (10) 37h Y
Read Defect Data (12) B7h Y
Read Extended 28h Y
DPO bit supported Y
FUA bit supported Y
Read Long 3Eh Y
Reassign Blocks 07h Y
Receive Diagnostic Results 1Ch Y
Supported Diagnostics pages (00h) Y
Translate page (40h) Y
Release 17h Y
Release (10) 57h Y
Request Sense 03h Y
Actual Retry Count bytes Y
Extended Sense Y
Field Pointer bytes Y
Reserve 16h Y
3rd Party Reserve Y
Extent Reservation N
Reserve (10) 56h Y
3rd Party Reserve Y
Extent Reservation N
Rezero Unit 01h Y
Search Data Equal 31h N
Search Data High 30h N
Search Data Low 32h N
Seek 0Bh Y
Seek Extended 2Bh Y
Send Diagnostics 1Dh Y
Supported Diagnostics pages (00h) Y
Translate page (40h) Y
Set Limits 33h N
Star t Unit/Stop Unit (spindle ceases rotating) 1Bh Y
Synchronize Cache 35h Y
48 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 55
Table 20: Commands supported by Cheetah 15K.6 SAS family drives (continued)
Command name Command code Supported
Test Unit Ready 00h Y
Verify 2Fh Y
BYTCHK bit Y
Write 0Ah Y
Write and Verify 2Eh Y
DPO bit Y
Write Buffer (modes 0, 2, supported) 3Bh Y
Firmware Download option
Y
(modes 5, 7, Ah and Bh supported) [3]
Write Extended 2Ah Y
DPO bit Y
FUA bit Y
Write Long 3Fh Y
Write Same 41h Y
PBdata N
LBdata N
XDRead 52h N
XDWrite 50h N
XPWrite 51h N
[1] Cheetah 15K.7 drives can format to 512, 520, 524, or 528 bytes per logical block.
[2] Warning. Power loss during flash programming can result in firmware corruption. This usually makes the
drive inoperable.
[3] Reference Mode Sense command 1Ah for mode pages supported.
[4] Y = Yes. Command is supported.
N = No. Command is not supported.
A = Support is available on special request.
Cheetah 15K.7 SAS Product Manual, Rev. D 49
Page 56
12.3.1 Inquiry data
Table lists the Inquiry command data that the drive should r eturn to the in itiator per the format given in the SAS
Interface Manual.
Table 21: Cheetah 15K.7 inquiry data
Bytes Data (hex)
0-15 00 00 xx** 12 8B 00 PP 02 53 45 41 47 41 54 45 20 Vendor ID
1
16-31 [535433 3630303035375353]
32-47 R# R# R# R# S# S# S# S# S# S# S# S# 00 00 00 00
48-63 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
64-79 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
80-95 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
96-111 00 43 6F 70 79 72 69 67 68 74 20 28 63 29 20 32* *Copyright
112-127 30* 30* 39* 20 53 65 61 67 61 74 65 20 41 6C 6C 20 notice
128-143 72 69 67 68 74 73 20 72 65 73 65 72 76 65 64 20
* Copyright year (changes with actual year).
** SCSI Revision support. Refer to the appropiate SPC release documentation for definitions.
PP 10 = Inquiry data for an Inquiry command received on Port A.
30 = Inquiry data for an Inquiry command received on Port B.
R# Four ASCII digits representing the last four digits of the product firmware release number.
S# Eight ASCII digits representing the eight digits of the product serial number.
[ ] Bytes 18 through 26 reflect model of drive. The table above shows the hex values for Model ST3600057SS.
20 20 20 20 20 Product ID
50 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 57
12.3.2 Mode Sense data
The Mode Sense command provides a way for the drive to report its operating parameters to the initiator. The
drive maintains four sets of mode parameters:
1. Default values
Default values are hard-coded in the drive firmware stored in flash E-PROM (nonvolatile memory) on the
drive’s PCB. These default values can be changed only by downloading a complete set of new firmware
into the flash E-PROM. An initiator can request and receive from the drive a list of default values and use
those in a Mode Select command to set up new current and saved values, where the values are change
able.
2. Saved values
Saved values are stored on the drive’s media using a Mode Select command. Only parameter values that
are allowed to be changed can be changed by this method. Parameters in the saved values list that are not
changeable by the Mode Select command get their values from default values storage.
When power is applied to the drive, it takes saved values from the media and stores them as current values in volatile memory. It is not possible to change the current values (or the saved values) with a Mode
Select command before the drive achieves operating speed and is “r ead y.” An attempt to do so results in a
“Check Condition” status.
On drives requiring unique saved values, the required unique saved values are stored into the saved values storage location on the media prior to shipping the drive. Some drives may have unique firmware with
unique default values also.
On standard OEM drives, the saved values are taken from the default values list and stored into the saved
values storage location on the media prior to shipping.
-
3. Current values
Current values are volatile values being used by the drive to control its operation. A Mode Select command
can be used to change the values identified as changeable values. Originally, current values are installed
from saved or default values after a power on reset, hard reset, or Bus Device Reset message.
4. Changeable values
Changeable values form a bit mask, stored in nonvolatile memory, that dictates which of the current values
and saved values can be changed by a Mode Select command. A one (1) indicates the value can be
changed. A zero (0) indicates the value is not changeable. For example, in Table
page 81, in the row entitled “CHG.” These are hex numbers representing the changeable values for Mode
page 81. Note in columns 5 and 6 (bytes 04 and 05), there is 00h which indicates that in bytes 04 and 05
none of the bits are changeable. Note also that bytes 06, 07, 09, 10, and 11 are not changeable, because
those fields are all zeros. In byte 02, hex value FF equates to the binary pattern 11111111. If there is a zero
in any bit position in the field, it means that bit is not changeable. Since all of the bits in byte 02 are ones,
all of these bits are changeable.
The changeable values list can only be changed by downloading new firmware into the flash E-PROM.
Note. Because there are often several dif ferent versions of drive control fir mware in the tota l population of
drives in the field, the Mode Sense values given in the following tables may not exactly match those
of some drives.
The following tables list the values of the data bytes returned by the d rive in response to the Mode Sense command pages for SCSI implementation (see the SAS Interface Manual ).
Definitions:
12.3.2.1, refer to Mode
DEF = Default value. Standard OEM drives are shipped configured this way.
CHG = Changeable bits; indicates if default value is changeable.
Cheetah 15K.7 SAS Product Manual, Rev. D 51
Page 58
12.3.2.1 600GBmodel Mode Sense data
MODE DATA HEADER:
01 6e 00 10 00 00 00 08
BLOCK DESCRIPTOR:
45 dd 2f b0 00 00 02 00
MODE PAGES:
DEF 81 0a c0 0b ff 00 00 00 05 00 ff ff
CHG 81 0a ff ff 00 00 00 00 ff 00 ff ff
DEF 82 0e 00 00 00 00 00 00 00 00 01 3a 00 00 00 00
CHG 82 0e 00 00 00 00 00 00 00 00 ff ff 00 00 00 00
DEF 83 16 bb d0 00 00 00 00 03 80 04 c4 02 00 00 01 00 c0 00 4c 40 00 00 00
CHG 83 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 84 16 01 8a 9a 08 00 00 00 00 00 00 00 00 00 00 00 00 00 00 3a a7 00 00
CHG 84 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 87 0a 00 0b ff 00 00 00 00 00 ff ff
CHG 87 0a 0f ff 00 00 00 00 00 00 ff ff
DEF 88 12 14 00 ff ff 00 00 ff ff ff ff 80 20 00 00 00 00 00 00
CHG 88 12 a5 00 00 00 ff ff ff ff 00 00 20 00 00 00 00 00 00 00
DEF 8a 0a 02 00 00 00 00 00 00 00 19 00
CHG 8a 0a 03 f0 00 00 00 00 00 00 00 00
DEF 18 06 06 00 00 00 00 00
CHG 18 06 00 00 00 00 00 00
DEF 99 06 06 00 07 d0 00 00
CHG 99 06 10 00 ff ff ff ff
DEF d9 01 00 64 00 06 00 02 00 00 00 00 10 29 0e 00 50 00 c5 00 00 68 64 a9 50 06 05 b0 00
29 2d d5 07 00 00 00 00 00 00 00 88 aa 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 01 00
00 10 29 0e 00 50 00 c5 00 00 68 64 aa 50 06 05 b0 00 29 2d d4 06 00 00 00 00 00 00 00 88
aa 00 00 00 00 00 00 00 00 00 00 00 00 00 00
CHG d9 01 00 64 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 f0 f0 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 f0
f0 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 59 02 00 0c 00 06 03 e8 00 00 00 00 00 00 00 00
CHG 59 02 00 0c 00 00 ff ff 00 00 00 00 00 00 00 00
DEF 59 03 00 2c 00 06 00 02 00 00 00 10 80 ac 00 01 80 ac 00 01 00 00 00 00 00 00 09 00 00
01 00 10 80 ac 00 01 80 ac 00 01 00 00 00 00 00 00 09 00
CHG 59 03 00 2c 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 9a 0a 00 02 00 00 00 05 00 00 8c a0
52 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 59
CHG 9a 0a 00 03 ff ff ff ff ff ff ff ff
DEF 9c 0a 10 00 00 00 00 00 00 00 00 01
CHG 9c 0a 9d 0f ff ff ff ff ff ff ff ff
DEF dc 01 00 0c 01 01 00 18 00 18 00 00 00 00 00 00
CHG dc 01 00 0c 00 01 ff ff ff ff 00 00 00 00 00 00
DEF 80 06 00 80 0f 00 00 00
CHG 80 06 b7 c0 8f 00 00 00
READ CAPACITY DATA:
READ BUFFER
0 1 2 3 4 5 6 7 8 9 A B C D E F ASCII
000000: 45 DD 2F AF 00 00 02 00 __ __ __ __ __ __ __ __
Cheetah 15K.7 SAS Product Manual, Rev. D 53
Page 60
12.3.2.2 450GB model Mode Sense data
MODE DATA HEADER:
01 76 00 10 00 00 00 08
BLOCK DESCRIPTOR:
34 65 f8 70 00 00 02 00
MODE PAGES:
DEF 81 0a c0 0b ff 00 00 00 05 00 ff ff
CHG 81 0a ff ff 00 00 00 00 ff 00 ff ff
DEF 82 0e 00 00 00 00 00 00 00 00 01 3a 00 00 00 00
CHG 82 0e 00 00 00 00 00 00 00 00 ff ff 00 00 00 00
DEF 83 16 bb d0 00 00 00 00 03 80 04 c4 02 00 00 01 00 c0 00 4c 40 00 00 00
CHG 83 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 84 16 01 8a 9a 06 00 00 00 00 00 00 00 00 00 00 00 00 00 00 3a a7 00 00
CHG 84 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 87 0a 00 0b ff 00 00 00 00 00 ff ff
CHG 87 0a 0f ff 00 00 00 00 00 00 ff ff
DEF 88 12 14 00 ff ff 00 00 ff ff ff ff 80 20 00 00 00 00 00 00
CHG 88 12 a5 00 00 00 ff ff ff ff 00 00 20 00 00 00 00 00 00 00
DEF 8a 0a 02 00 00 00 00 00 00 00 12 c0
CHG 8a 0a 03 f0 00 00 00 00 00 00 00 00
DEF 18 06 06 00 00 00 00 00
CHG 18 06 00 00 00 00 00 00
DEF 99 0e 06 00 07 d0 00 00 00 00 00 00 00 00 00 00
CHG 99 0e 10 00 ff ff ff ff 00 00 00 00 00 00 00 00
DEF d9 01 00 64 00 06 00 02 00 00 00 00 10 29 0e 00 50 00 c5 00 00 15 4b 65 50 06 05 b0 00
29 28 55 07 00 00 00 00 00 00 00 88 aa 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 01 00
00 10 29 0e 00 50 00 c5 00 00 15 4b 66 50 06 05 b0 00 29 28 54 06 00 00 00 00 00 00 00 88
aa 00 00 00 00 00 00 00 00 00 00 00 00 00 00
CHG d9 01 00 64 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 f0 f0 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 f0
f0 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 59 02 00 0c 00 06 03 e8 00 00 00 00 00 00 00 00
CHG 59 02 00 0c 00 00 ff ff 00 00 00 00 00 00 00 00
DEF 59 03 00 2c 00 06 00 02 00 00 00 10 80 ac 00 01 80 ac 00 01 00 00 00 00 00 00 09 00 00
01 00 10 80 ac 00 01 80 ac 00 01 00 00 00 00 00 00 09 00
CHG 59 03 00 2c 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 9a 0a 00 02 00 00 00 05 00 00 8c a0
CHG 9a 0a 00 03 ff ff ff ff 00 00 00 00
54 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 61
DEF 9c 0a 10 00 00 00 00 00 00 00 00 01
CHG 9c 0a 9d 0f ff ff ff ff ff ff ff ff
DEF dc 01 00 0c 01 01 00 18 00 18 00 00 00 00 00 00
CHG dc 01 00 0c 00 01 ff ff ff ff 00 00 00 00 00 00
DEF 80 06 00 80 0f 00 00 00
CHG 80 06 b7 c0 8f 00 00 00
READ CAPACITY DATA:
READ BUFFER
0 1 2 3 4 5 6 7 8 9 A B C D E F
000000: 34 65 F8 6F 00 00 02 00
Cheetah 15K.7 SAS Product Manual, Rev. D 55
Page 62
12.3.2.3 300GB model Mode Sense data
MODE DATA HEADER:
01 76 00 10 00 00 00 08
BLOCK DESCRIPTOR:
22 ec b2 5c 00 00 02 00
MODE PAGES:
DEF 81 0a c0 0b ff 00 00 00 05 00 ff ff
CHG 81 0a ff ff 00 00 00 00 ff 00 ff ff
DEF 82 0e 00 00 00 00 00 00 00 00 01 3a 00 00 00 00
CHG 82 0e 00 00 00 00 00 00 00 00 ff ff 00 00 00 00
DEF 83 16 bb d0 00 00 00 00 03 80 04 c4 02 00 00 01 00 c0 00 4c 40 00 00 00
CHG 83 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 84 16 01 8a 9a 04 00 00 00 00 00 00 00 00 00 00 00 00 00 00 3a a7 00 00
CHG 84 16 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 87 0a 00 0b ff 00 00 00 00 00 ff ff
CHG 87 0a 0f ff 00 00 00 00 00 00 ff ff
DEF 88 12 14 00 ff ff 00 00 ff ff ff ff 80 20 00 00 00 00 00 00
CHG 88 12 a5 00 00 00 ff ff ff ff 00 00 20 00 00 00 00 00 00 00
DEF 8a 0a 02 00 00 00 00 00 00 00 0c 80
CHG 8a 0a 03 f0 00 00 00 00 00 00 00 00
DEF 18 06 06 00 00 00 00 00
CHG 18 06 00 00 00 00 00 00
DEF 99 0e 06 00 07 d0 00 00 00 00 00 00 00 00 00 00
CHG 99 0e 10 00 ff ff ff ff 00 00 00 00 00 00 00 00
DEF d9 01 00 64 00 06 00 02 00 00 00 00 14 0a 0e 00 50 00 c5 00 00 5f 66 d5 50 00 00
00 80 00 00 00 01 00 00 00 00 00 00 00 88 aa 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 01 00 00 14 2a 0e 00 50 00 c5 00 00 5f 66 d6 50 00 00 00 80 00 00 01 03 00 00 00 00
00 00 00 88 aa 00 00 00 00 00 00 00 00 00 00 00 00 00 00
CHG d9 01 00 64 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 00 00 f0 f0 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 f0 f0 00 00 00 00 00 00 00 00 00 00 00 00 00 00
DEF 59 02 00 0c 00 06 03 e8 00 00 00 00 00 00 00 00
CHG 59 02 00 0c 00 00 ff ff 00 00 00 00 00 00 00 00
DEF 59 03 00 2c 00 06 00 02 00 00 00 10 80 ac 00 01 80 ac 00 01 80 a8 00 00 00 00 0a
00 00 01 00 10 80 ac 00 01 80 ac 00 01 80 a8 00 00 00 00 0a 00
CHG 59 03 00 2c 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00 00
56 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 63
DEF 9a 0a 00 02 00 00 00 05 00 00 8c a0
CHG 9a 0a 00 03 ff ff ff ff 00 00 00 00
DEF 9c 0a 10 00 00 00 00 00 00 00 00 01
CHG 9c 0a 9d 0f ff ff ff ff ff ff ff ff
DEF dc 01 00 0c 01 01 00 18 00 18 00 00 00 00 00 00
CHG dc 01 00 0c 00 01 ff ff ff ff 00 00 00 00 00 00
DEF 80 06 00 80 0f 00 00 00
CHG 80 06 b7 c0 8f 00 00 00
READ CAPACITY DATA:
READ BUFFER
0 1 2 3 4 5 6 7 8 9 A B C D E F ASCII
00000: 22 EC B2 5B 00 00 02 00 __ __ __ __ __ __ __ __
12.4 Miscellaneous operating features and conditions
Table 22 lists various features and conditions. A “Y” in the support column indicates the feature or condition is
supported. An “N” in the support column indicates the feature or condition is not supported.
Table 22: Miscellaneous features
Supported Feature or condition
N Automatic contingent allegiance
N Asynchronous event notification
N Synchronized (locked) spindle operation
Y Segmented caching
N Zero latency read
Y Queue tagging (up to 64 queue tags supported)
Y Deferred error handling
Y Parameter rounding (controlled by Round bit in Mode Select page 0)
Y Reporting actual retry count in Extended Sense bytes 15, 16, and 17
N Adaptive caching
Y SMP = 1 in Mode Select command needed to save RPL and rotational offset bytes
Cheetah 15K.7 SAS Product Manual, Rev. D 57
Page 64
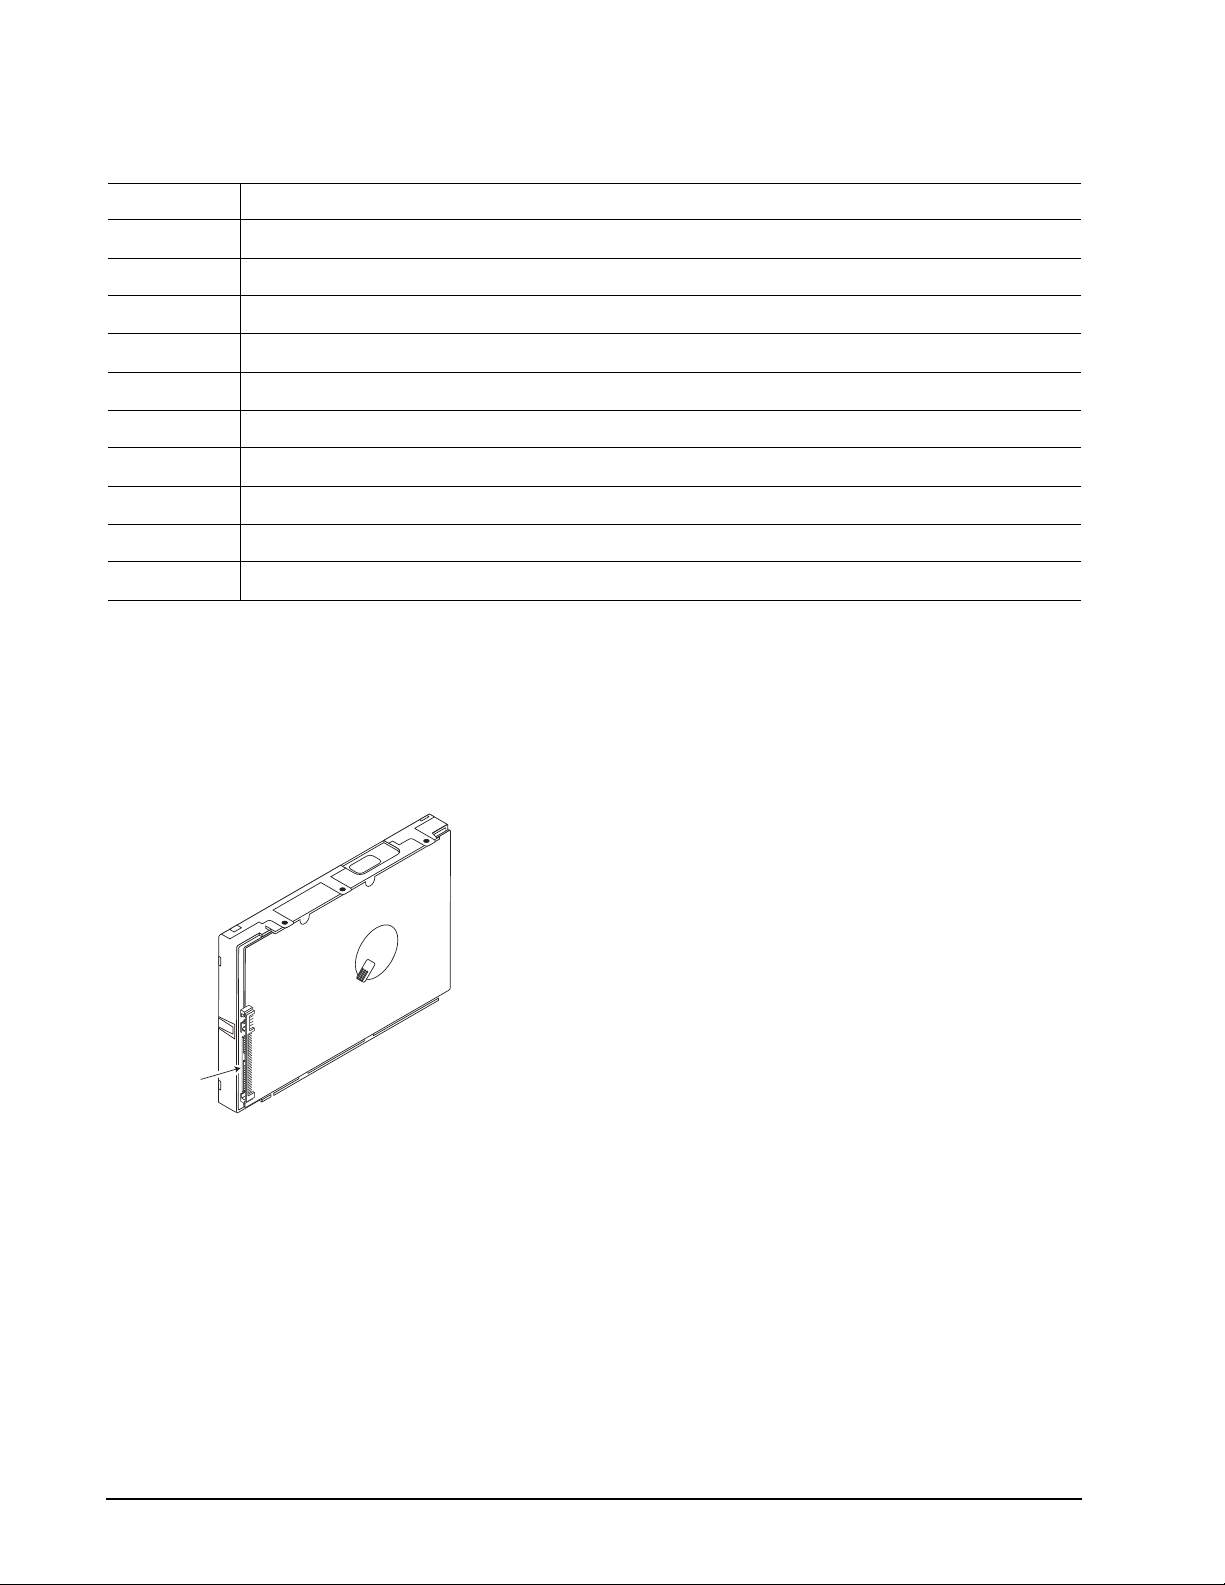
Table 23: Miscellaneous status
Supported Status
YGood
Y Check condition
Y Condition met/good
YBusy
Y Intermediate/good
Y Intermediate/conditi on met/good
Y Reservation conflict
YTask set full
N ACA active
N ACA active, faulted initiator
12.4.1 SAS physical interface
Figure 12 shows the location of the SAS device connector J1. Figures 13 and 14 provide the dimensions of the
SAS device.
Details of the physical, electrical, and logical characteristics are provided within this section. The operational
aspects of Seagate’s SAS drives are provided in the SAS Interface Manual..
SAS Interface
connector
Figure 12. Physical interfac e
58 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 65
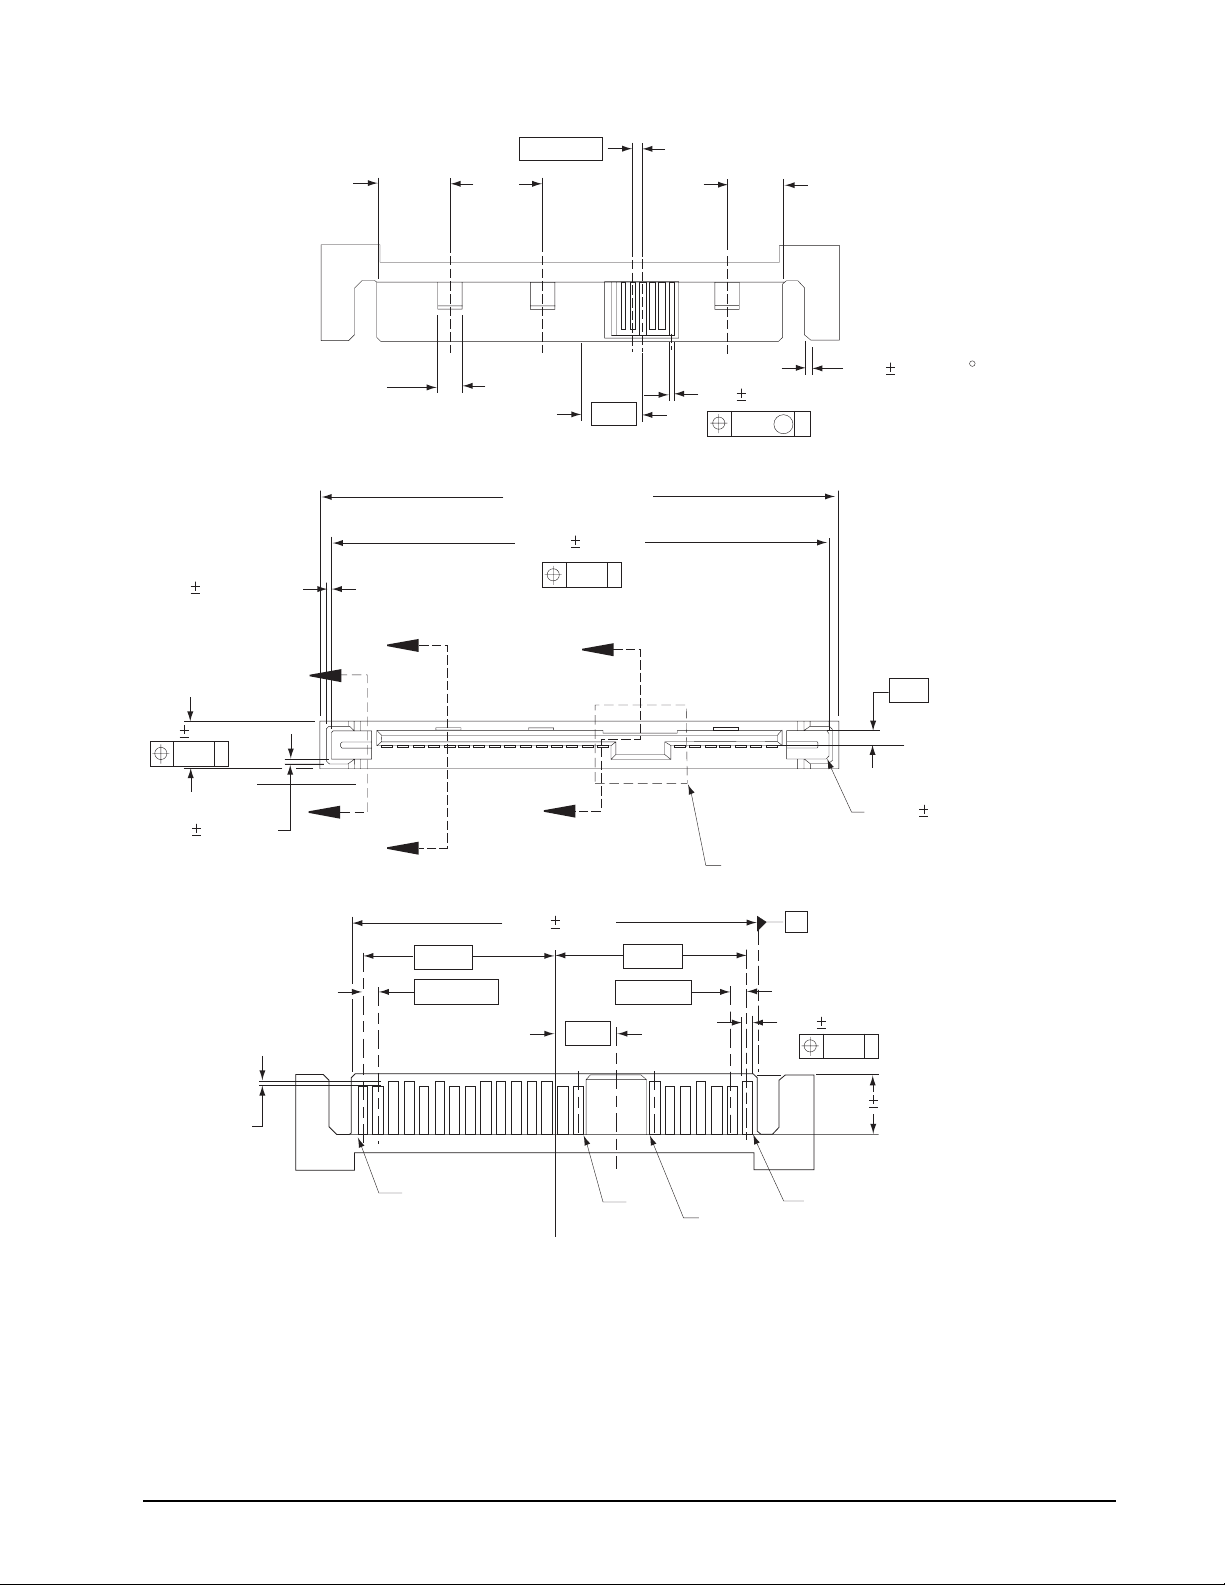
0.80 (6X)
0.30 0.05 (2X)
4.00 0.08
0.15 D
2.00 (3X)
7.625.92
5.08
42.73 REF.
41.13 0.15
0.20 B
C
A
4.65
0.52 0.08 x 45
0.45 0.03 (7X)
0.10 M E
B
1.10
C OF DATUM D
L
0.30 0.05 (4X)
0.35MIN
B
C
15.875
1.27 (14X)
P15
Figure 13. SAS connector dimensions
33.43 0.05
5.08
C OF DATUM B
L
A
15.875
1.27 (6X)
P1
R0.30 0.08 (4X)
SEE Detail1
B
0.84 0.05 (22X)
0.15 B
4.90 0.08
S1
S7
Cheetah 15K.7 SAS Product Manual, Rev. D 59
Page 66
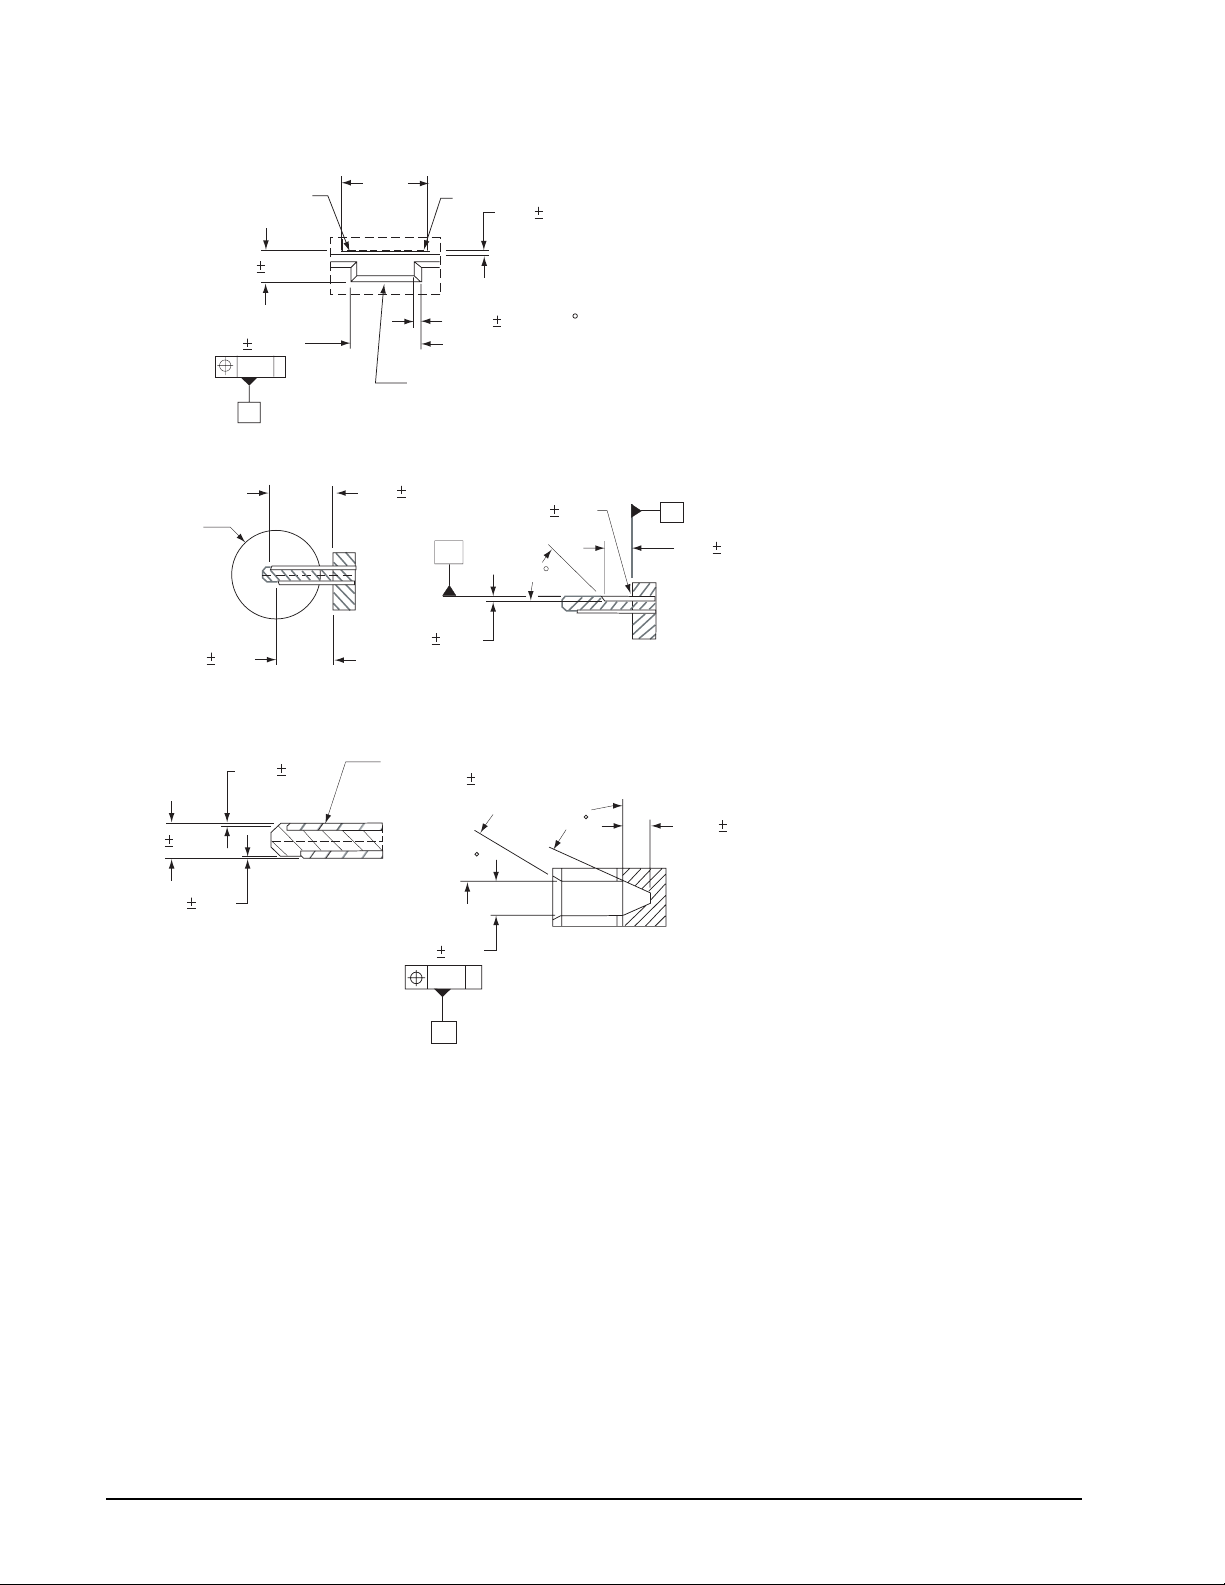
Detail A
SEE Detail 2
3.90 0.15
2.25 0.05
4.85 0.05
0.10 B
E
SECTION A - A
0.08 0.05
S14
6.10
4.40 0.15
0.35 0.05
CONTACT SURFACE FLUSH
TO DATUM A 0.03
S8
0.40 0.05 X 45 (3X)
CORING ALLOWED
IN THIS AREA.
A
0.30 0.05 x 45 (5X)
R0.30 0.08
45
SECTION C - C
C
1.95 0.08
1.23 0.05
65
30
Detail 2
0.08 0.05
2.40 0.08
0.10 A
SECTION B - B
D
1.90 0.08
Figure 14. SAS connector dimensions
12.4.2 Physical characteristics
This section defines physical interface connector.
12.4.3 Connector requirements
The SAS connector on the drive complies with SFF-8482. Contact your preferred connector manufacturer for
mating part information.
The SAS device connector is illustrated in Figures 13 and 14.
60 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 67
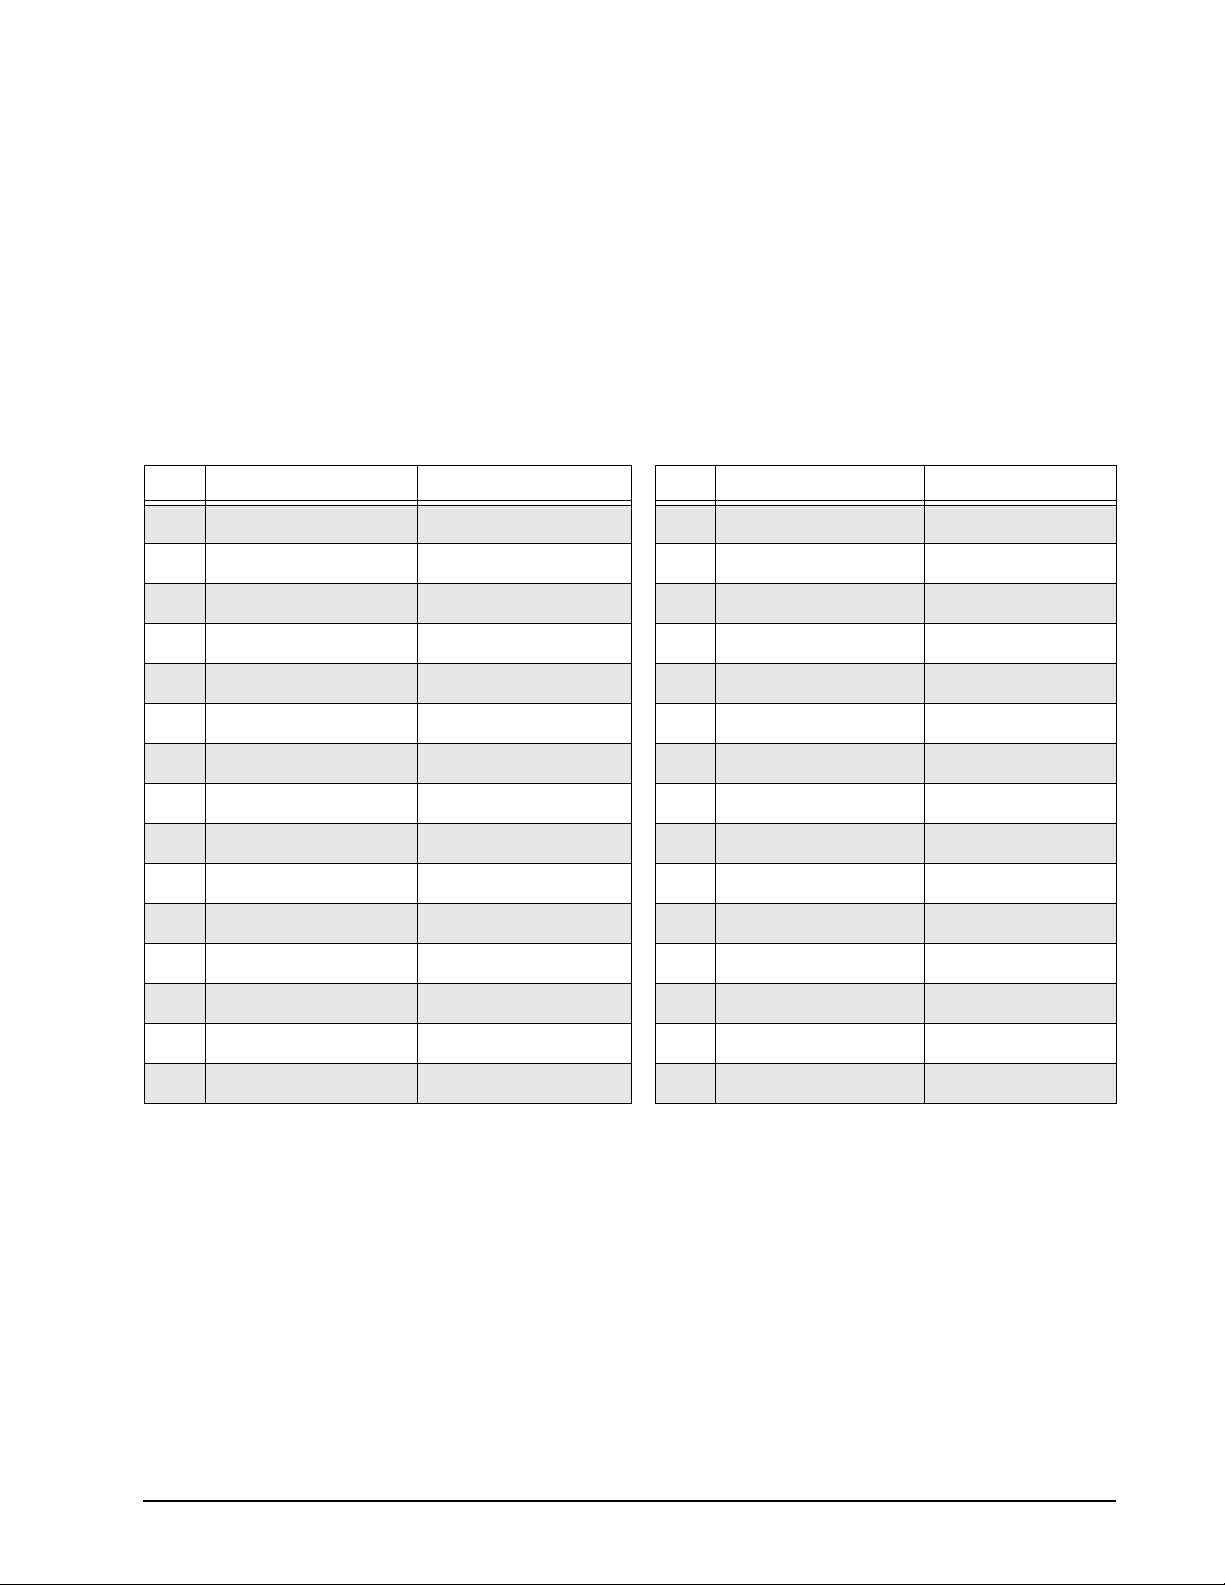
12.4.4 Electrical description
SAS drives use the device connector for:
• DC power
• SAS interface
• Activity LED
This connector is designed to either plug directly into a backpanel or accept cables.
12.4.5 Pin descriptions
This section provides a pin-out of the SAS device and a description of the functions provided by the pins.
Table 24: SAS pin descriptions
Pin Signal name Signal type Pin Signal name Signal type
S1 Port A Ground P1* NC (reserved 3.3Volts)
S2* +Port A_in Diff. input pair P2* NC (reserved 3.3Volts)
S3* -Port A_in P3 NC (reserved 3.3Volts)
S4 Port A Ground P4 Ground
S5* -Port A_out Diff output pair P5 Ground
S6* +Port A_out P6 Ground
S7 Port A Ground P7 5 Volts charge
S8 Port B Ground P8* 5 Volts
S9* +Port B_in Diff. input pair P9* 5 Volts
S10* -Port B_in P10 Ground
S11 Port A Ground P1 1* Ready LED Open collector out
S12* -Port B_out Dif f output pair P12 Ground
S13* +Port B_out P13 12 V olts charge
S14 Port B Ground P14* 12 Volts
P15* 12 Volts
* - Short pin to support hot plugging
NC - No connection in the drive.
Cheetah 15K.7 SAS Product Manual, Rev. D 61
Page 68
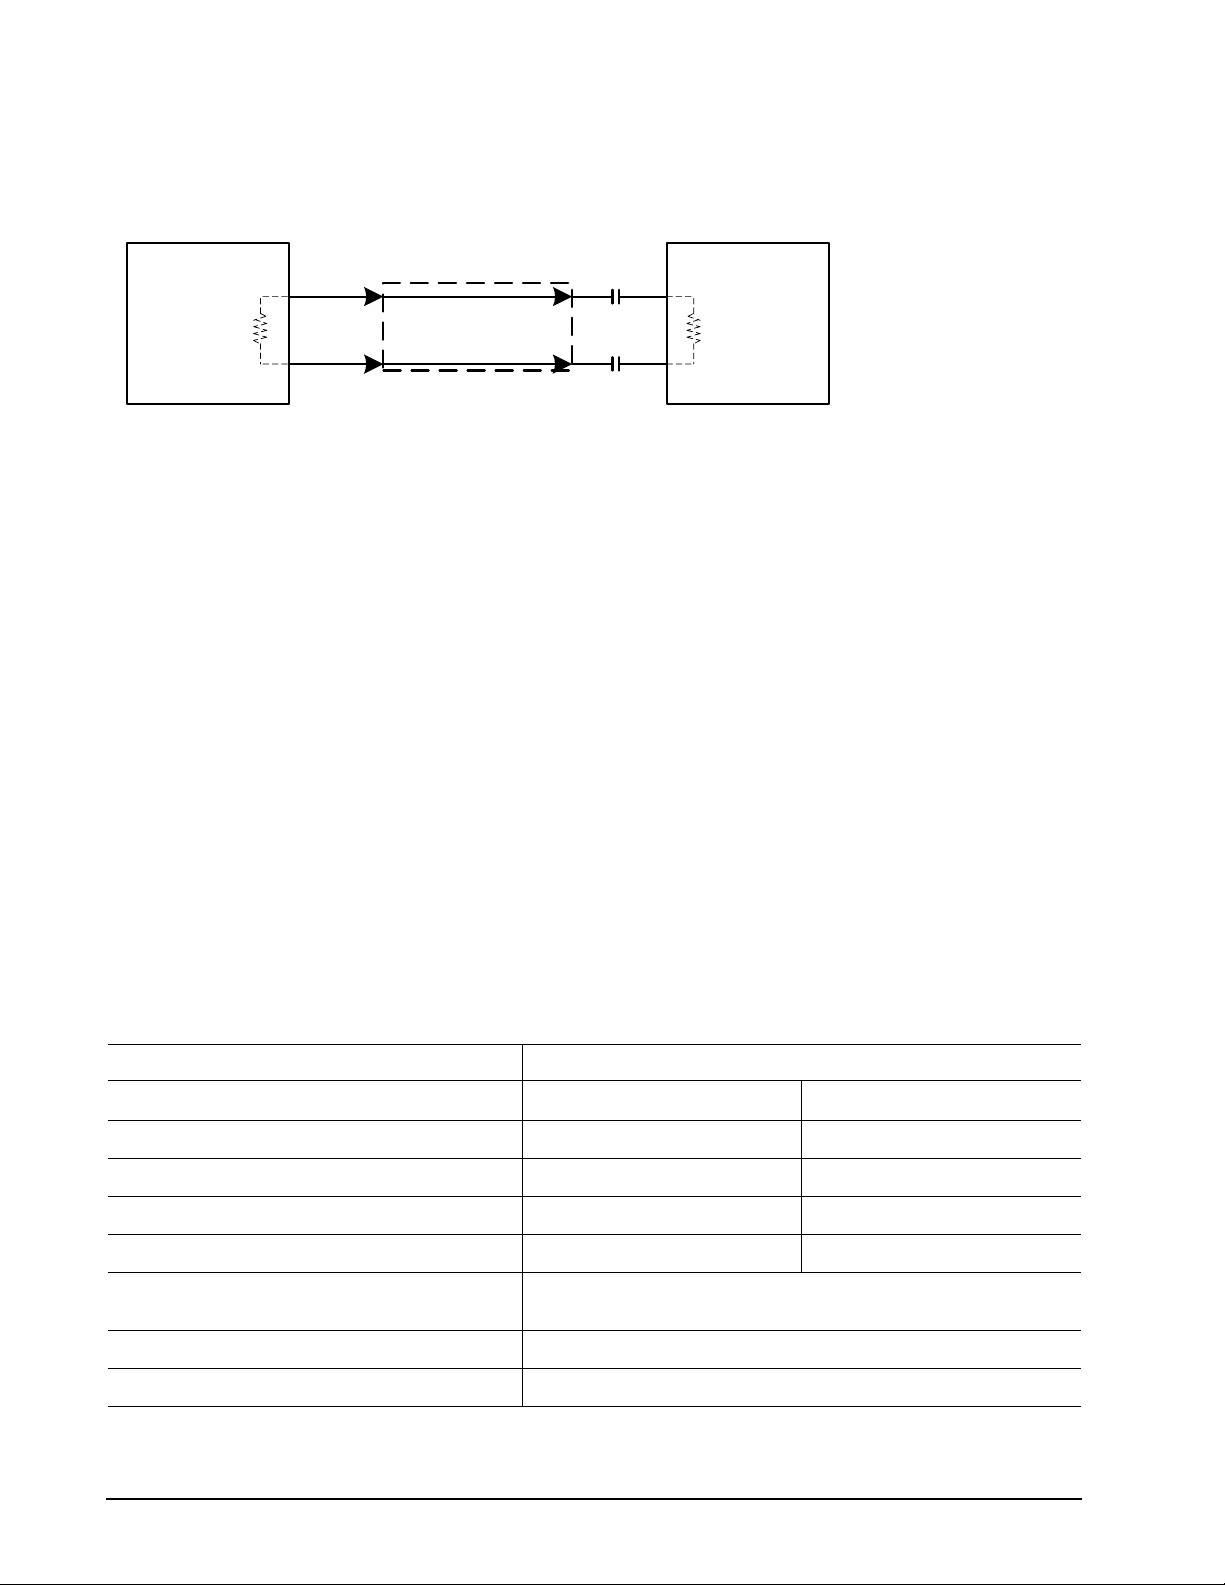
12.4.6 SAS transmitters and receivers
A typical SAS differential copper transmitter and receiver pair is shown in Figure 15. The receiver is AC coupling to eliminate ground shift noise.
TX
Transmitter
TY
Figure 15. SAS transmitters and receivers
Differential
Transfer Medium
.01
.01
RX
Receiver
100100
RY
12.4.7 Power
The drive receives power (+5 volts and +12 volts) through the SAS device connector.
Three +12 volt pins provide power to the drive, 2 short and 1 long. The current return for the +12 volt power
supply is through the common ground pins. The supply current and return current must be distributed as
evenly as possible among the pins.
Three +5 volt pins provide power to the drive , 2 short and 1 long. The current return for the +5 volt power supply is through the common ground pins. The supply curre nt and re turn curr ent must be di stributed as evenly as
possible among the pins.
Current to the drive through the long power pins may be limited by the system to reduce inrush current to the
drive during hot plugging.
12.5 Signal characteristics
This section describes the electrical signal characteristics of the drive’s input and output signals. See Table 24
for signal type and signal name information.
12.5.1 Ready LED Out
The Ready LED Out signal is driven by the drive as indicated in Table 25.
Table 25: Ready LED Out conditions
Normal command activity LED status
Ready LED Meaning bit mode page 19h
Spun down and no activity Off Off
Spun down and activity (command executing) On On
Spun up and no activity On Off
Spun up and activity (command executing) Off On
Spinning up or down Blinks steadily
(50% on and 50% off, 0.5 seconds on and off for 0.5 seconds)
Format in progress Toggles on/off
Write Same command in progress Toggles on/off
01
62 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 69
The Ready LED Out signal is designed to pull down the cathode of an LED. The anode is attached to the
proper +3.3 volt supply through an appropriate current limiting resistor. The LED and the current limiting resistor are external to the drive. See Table 26 for the output characteristics of the LED drive signals.
Table 26: LED drive signal
State Test condition Output voltage
LED off, high 0 V
LED on, low I
≤ VOH ≤ 3.6 V -100 µA < I
= 15 mA 0 ≤ VOL ≤ 0.225 V
OL
< 100 µA
OH
12.5.2 Differential signals
The drive SAS differential signals comply with the intra-enclosure (internal connector) requirements of the SAS
standard.
Table 27 defines the general interface characteristics.
Table 27: General interface characteristics
Characteristic Units 1.5 Gbps 3.0 Gbps 6.0 Gbps
Bit rate (nominal) Mbaud 1,500 3,000 6,000
Unit interval (UI)(nominal) ps 666.6 333.3 166.6
Impedance (nominal, differential ) ohm 100 100 100
Transmitter transients, maximum V ± 1.2 ± 1.2 ± 1.2
Receiver transients, maximum V ± 1.2 ± 1.2 ± 1.2
12.6 SAS-2 Specification compliance
Seagate SAS-2 drives are entirely compatible with the latest SAS-2 Specification (T10/1760-D) Revision 16.
The most important characteristic of the SAS-2 drive at 6 Gbps is that the receiver is capable of adapting the
equalizer to optimize the receive margins. The SAS-2 drive has two types of equalizers:
1. A Decision Feedback Equalizer (DFE) which utilizes th e standard SAS-2 training pattern transmitted during the SNW-3 training gap. The DFE circuit can derive an optimal equalization characteristic to compensate for many of the receive losses in the system.
2. A Feed Forward Equa lizer (FF E) optimize d to prov ide balanced receive margins over a range of channels
bounded by the best and worst case channels as defined by the relevant ANSI standard.
12.7 Additional information
Please contact your Seagate representative for SAS electrical details, if required.
For more information about the Phy, Link, Transport, and Applications layers of the SAS interface, refer to the
Seagate SAS Interface Manual, part number 100293071.
For more information about the SCSI commands used by Seagate SAS drives, refer to the Seagate SCSI
Commands Reference Manual, part number 100293068.
Cheetah 15K.7 SAS Product Manual, Rev. D 63
Page 70
64 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 71
Index
Numerics
12 volt
pins 62
5 volt pins 62
6 Gbps 63
A
abort task set function 45
AC coupling 62
AC power requirements 20
ACA active status 58
ACA active, faulted initiator status 58
acoustics 33
active LED Out signal 62
actuator
assembly design 6
adaptive caching 57
Admin SP 36
AES-128 data encryption 36
AFR 8
air cleanliness 33
air flow 43, 44
illustrated 44
air inlet 43
altitude 30
ambient 30
ambient temperature 43
ANSI documents
Serial Attached SCSI 5
asynchronous event notification 57
audible noise 3
auto write and read reallocation
programmable 7
automatic contingent allegiance 57
average idle current 21, 22, 23
average rotational latency 9
B
Background Media Scan 41
backpanel 61
Band 0 37
BandMasterX 36
BMS 41
buffer
data 7
space 11
busy status 58
C
cache operation 11
cache segments 11
caching write data 12
Canadian Department of Communications 3
capacity
unformatted 9
CBC 36
check condition status 58
chemical pollutants 33
Cipher Block Chaining 36
class B limit 3
clear ACA function 45
clear task set function 45
commands supported 46
condensation 30
condition met/good status 58
connector
illustrated 60
requirements 60
continuous vibration 33
cooling 43
corrosive environment 33
CRC
error 14
Cryptographic erase 37
Current profiles 24
customer service 19
D
DAR 42
Data Bands 37
data bands 36
Data encryption 36
Data Encryption Key 36
data heads
read/write 9
data rate
internal 9
data transfer rate 10
DC power 61
requirements 20
Decision Feedback Equalizer 63
decrypt 36
default MSID password 37
defect and error management 39
defects 39
Deferred Auto-Reallocation 42
deferred error handling 57
DEK 36
description 6
DFE 63
dimensions 34
disc rotation speed 9
drive 33
drive characteristics 9
Drive Locking 37
Cheetah 15K.7 SAS Product Manual, Rev. D 65
Page 72
drive mounting 34, 44
drive select 61
dual port support 46
E
electrical
description of connector 61
signal characteristics 62
specifications 20
electromagnetic compatibility 3
electromagnetic susceptibility 34
EMI requirements 3
encryption engine 36
encryption key 37
environment 43
environmental
limits 29
requirements 13
environmental control 33
EraseMaster 36
error
management 39
rates 13
errors 39
F
FCC rules and regulations 3
features 7
interface 45
feed forward equalizer 63
FFE 63
FIPS 35
firmware 7
corruption 49
firmware download port 37
flawed sector reallocation 7
Format command execution time 10
function
complete, code 00 45
not supported, code 05 45
reject, code 04 45
G
Global Data Band 37
Good status 58
gradient 30
ground shift noise 62
grounding 44
H
HDA 43, 44
head and disc assembly. See HDA
heads
read/write data 9
heat removal 43
heat source 43
host equipment 44
hot plugging the drive 14
humidity 30
humidity limits 29
I
Idle Read After Write 42
inquiry data 50
installation 43
interface
commands supported 46
error rate 13
errors 14
illustrated 58
physical 58
requirements 45
intermediate/condition met/good status 58
intermediate/good status 58
internal data rate 9
internal defects/errors 39
internal drive characteristics 9
IRAW 42
J
jumpers 43
L
latency
average rotational 9, 10
Locking SP 36
LockOnReset 37
logical block address 11
logical block reallocation scheme 7
logical block size 7, 10
logical segments 11
M
maintenance 13
Makers Secure ID 36
maximum delayed motor start 21, 22, 23
maximum start current 21, 22, 23
media description 7
Media Pre-Scan 42
miscellaneous feature support
Adaptive caching 57
Asynchronous event notification 57
Automatic contingent allegiance 57
Deferred error handling 57
Parameter rounding 57
Queue tagging 57
66 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 73
Reporting actual retry count 57
Segmented caching 57
SMP = 1 in Mode Select command 57
Synchronized (locked) spindle operation 57
Zero latency read 57
miscellaneous status support
ACA active 58
ACA active, faulted initiator 58
Busy 58
Check condition 58
Condition met/good 58
Good 58
Intermediate/condition met/good 58
Intermediate/good 58
Reservation conflict 58
Task set full 58
miscorrected media data 13
Mode sense
data, table 51
mounting 44
holes 44
orientations 43
MSID 36, 37
N
noise
audible 3
noise immunity 24
non-operating 30, 31, 33
temperature 30
non-operating vibration 33
O
office environment 33
operating 30, 32
option selection 61
out-of-plane distortion 44
P
package size 31
package test specification 5
packaged 31
parameter rounding 57
password 36, 37
passwords 36
PCBA 44
peak bits per inch 9
peak operating current 21, 22, 23
peak-to-peak measurements 24
performance characteristics
detailed 9
general 10
performance degradation 31
performance highlights 7
physical damage 33
physical dimensions 34
physical interface 58
physical specifications 20
pin descriptions 61
power 62
dissipation 27
requirements, AC 20
requirements, DC 20
sequencing 24
power distribution 3
PowerCycle 37
prefetch/multi-segmented cache control 11
preventive maintenance 13
protection of data at rest 36
Q
queue tagging 57
R
radio interference regulations 3
Random number generator 37
RCD bit 11
read error rates 13, 39
read/write data heads 9
receivers 62
recommended mounting 32
Recoverable Errors 13
recovered media data 13
reference
documents 5
relative humidity 30
reliability 8
specifications 13
reliability and service 14
repair and return information 19
reporting actual retry count 57
reservation conflict status 58
resonance 30
return information 19
RNG 37
rotation speed 9
S
safety 3
SAS
interface 61
physical interface 58
task management functions 45
SAS documents 5
SAS Interface Manual 3, 5
SCSI interface
commands supported 46
Secure ID 36
Cheetah 15K.7 SAS Product Manual, Rev. D 67
Page 74
security partitions 36
Security Protocol In 36
Security Protocol Out 36
seek error
defined 14
rate 13
seek performance characteristics 9
seek time
average typical 9
full stroke typical 9
single track typical 9
segmented caching 57
self-encrypting drives 36
Self-Monitoring Analysis and Reporting Technology
8, 15
Serial Attached SCSI (SAS) Interface Manual 2
shielding 3
shipping 19
shipping container 30
shock 30, 31
and vibration 30
shock mount 44
SID 36
signal
characteristics 62
single-unit shipping pack kit 8
SMART 8, 15
SMP = 1 in Mode Select command 57
SNW-3 training gap 63
spindle brake 7
standards 3
start/stop time 10
Sulfur 33
support services 1
surface stiffness
allowable for non-flat surface 44
switches 43
synchronized spindle
operation 57
system chassis 44
limits 29
non-operating 30
regulation 3
See also cooling
terminate task function 45
terminators 43
tracks per inch 9
transmitters 62
transporting the drive 19
Trusted Computing Group 36
U
unformatted 8
Unrecoverable Errors 13
unrecovered media data 13
V
vibration 30, 32, 33
W
warranty 19
Z
zero latency read 57
zone bit recording (ZBR) 7
T
task management functions 45
Abort task set 45
Clear ACA 45
Clear task set 45
terminate task 45
task management response codes 45
Function complete 00 45
Function not supported 05 45
Function reject 04 45
task set full status 58
TCG 36
technical support services 1
temperature 29, 43
68 Cheetah 15K.7 SAS Product Manual, Rev. D
Page 75
Page 76
Seagate Technology LLC
920 Disc Drive, Scotts Valley, California 95066-4544, USA
Publication Number: 100516226, Rev. D
 Loading...