

Page 1
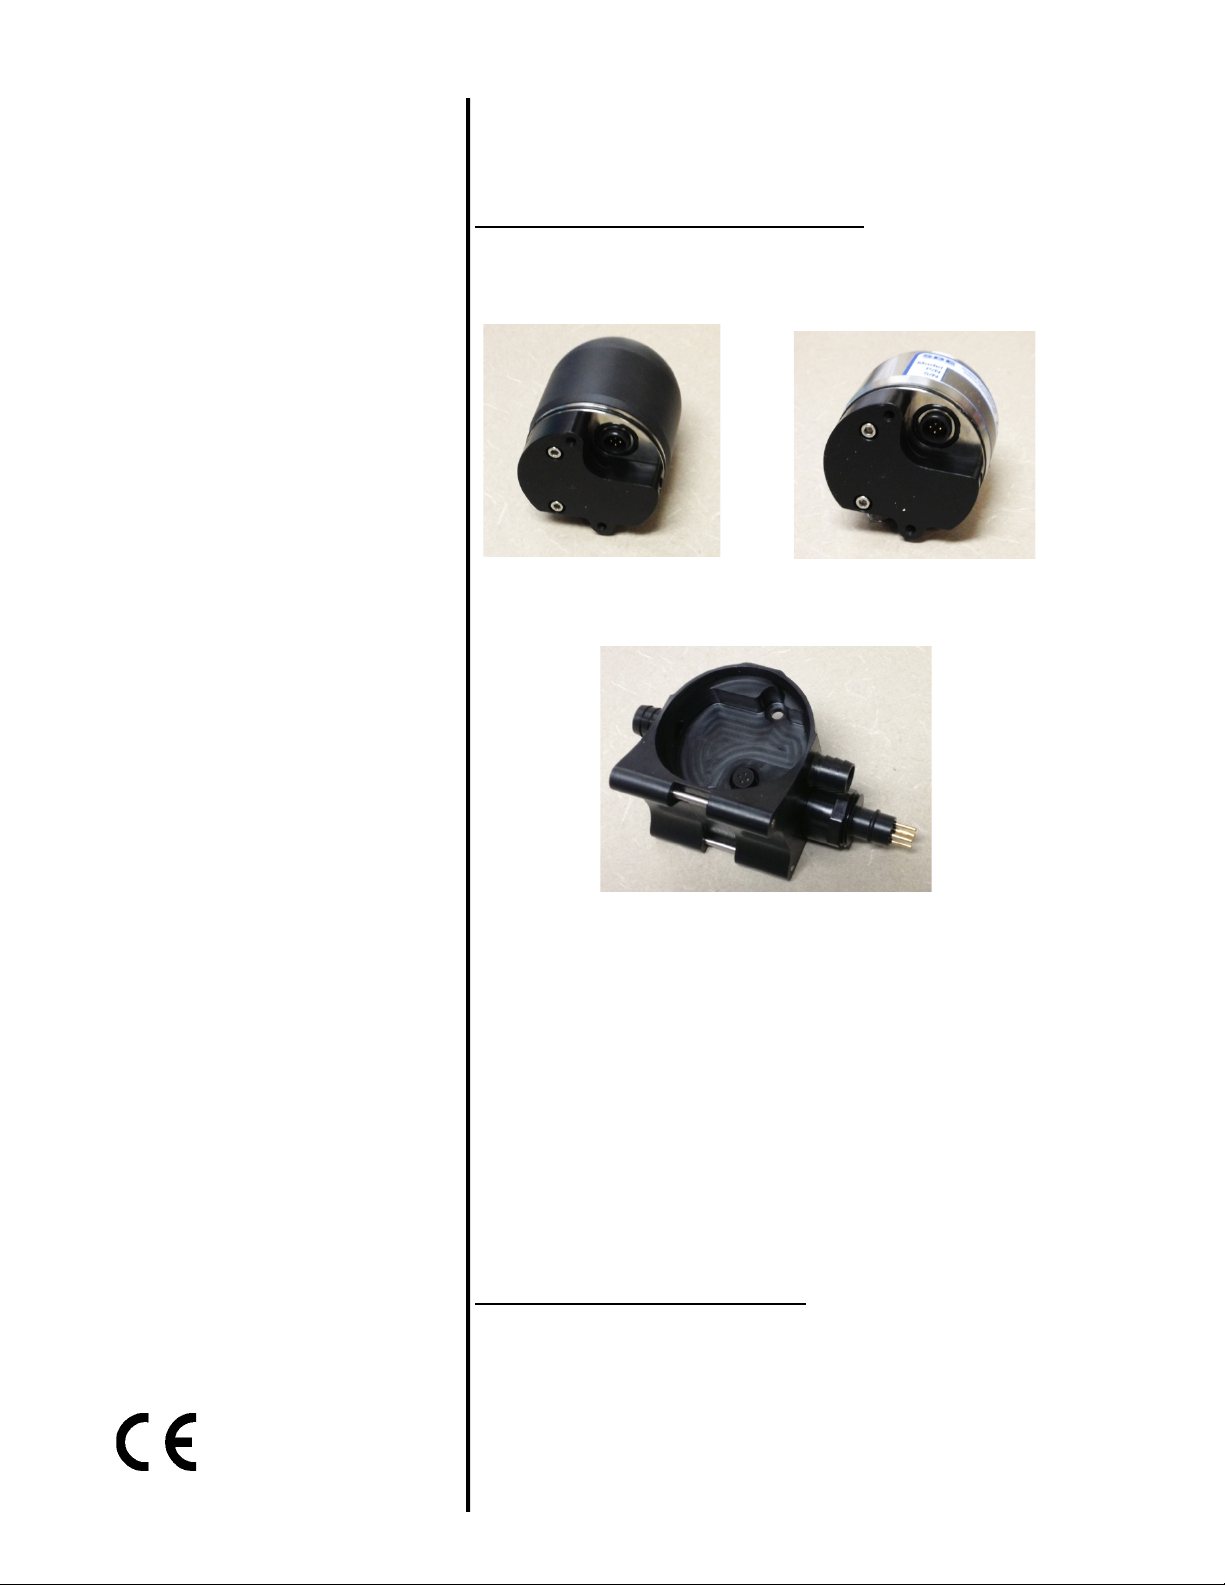
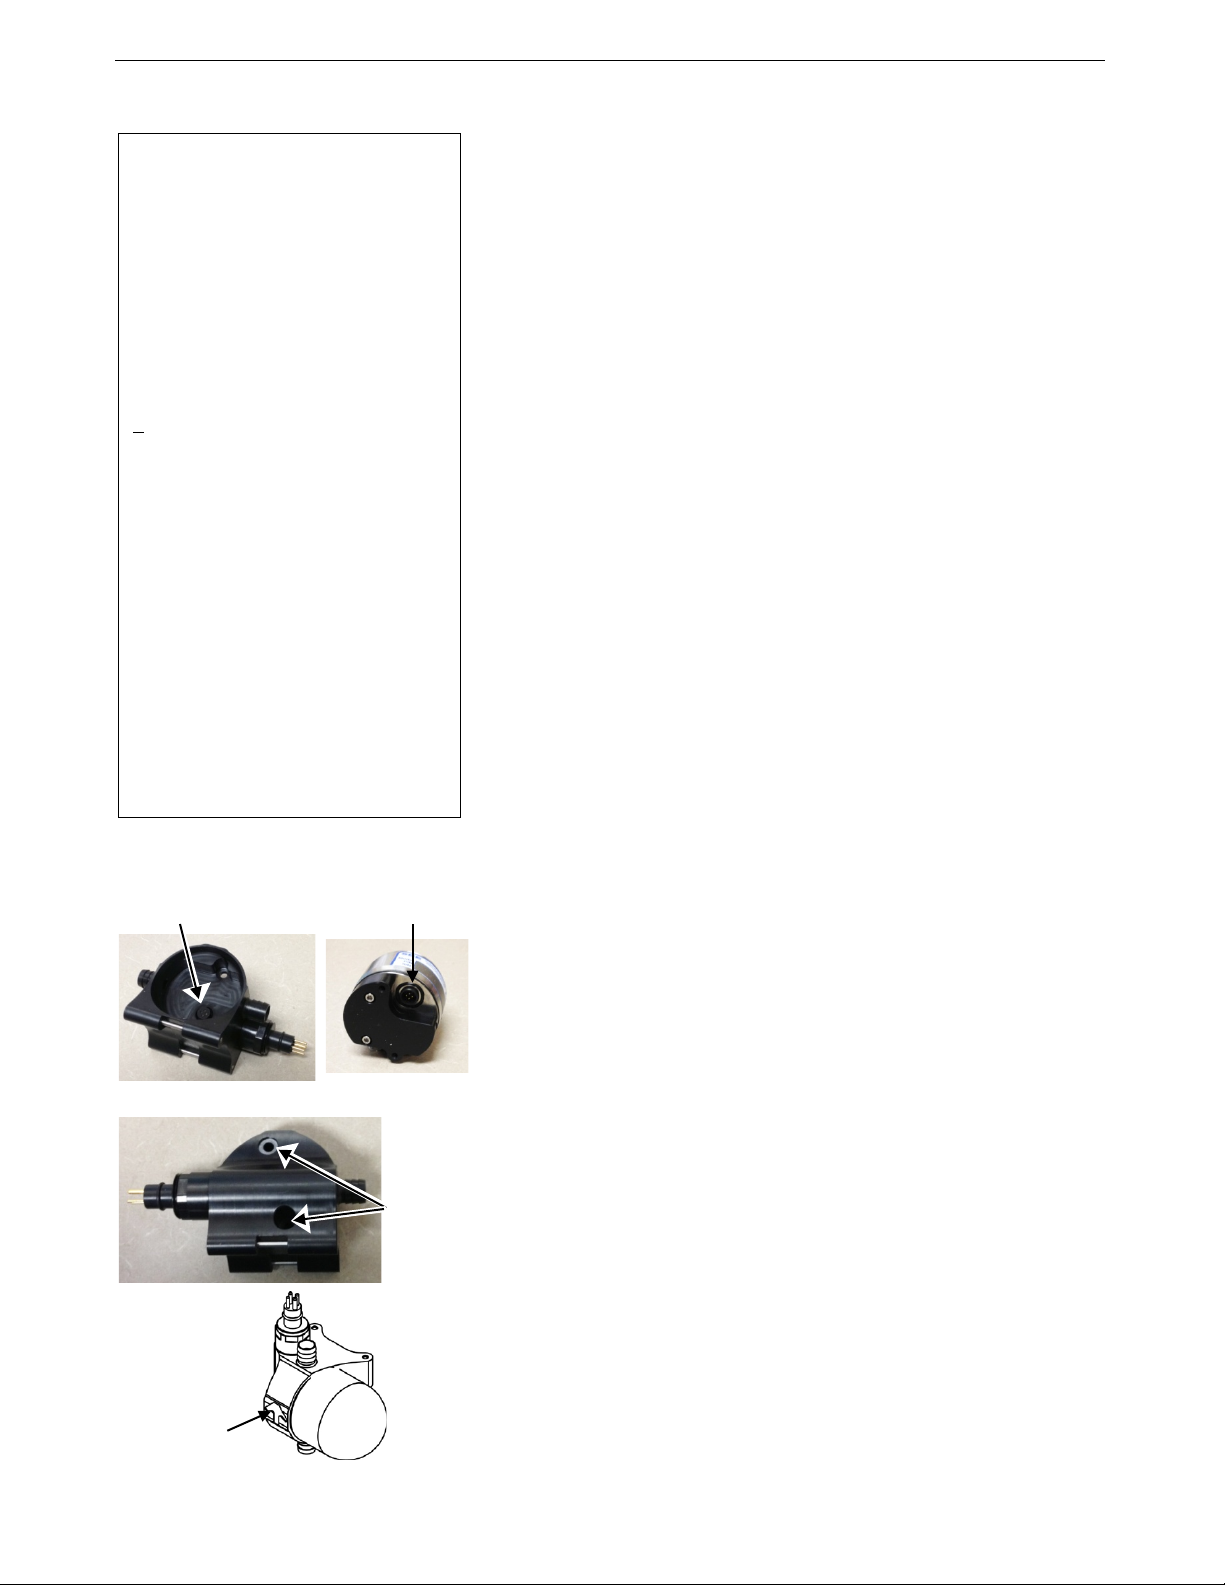
Optional Sensor Mount for
installation on SeaCAT CTD
SBE 63 DO Sensor
(plastic housing)
SBE 63 DO Sensor
(titanium housing)
SBE 63
Digital Optical Dissolved Oxygen Sensor
User’s Manual
Sea-Bird Electronics, Inc.
13431 NE 20
Bellevue, Washington 98005 USA
Telephone: 425/643-9866
Fax: 425/643-9954 Manual Version #005, 04/15/13
E-mail: [email protected] Firmware Version 3.0.1 and later
Website: www.seabird.com SeatermV2 version 2.2.6 and later
th
Street
Page 2
Limited Liability Statement
Extreme care should be exercised when using or servicing this equipment. It should be used or serviced
only by personnel with knowledge of and training in the use and maintenance of oceanographic
electronic equipment.
SEA-BIRD ELECTRONICS, INC. disclaims all product liability risks arising from the use or servicing
of this system. SEA-BIRD ELECTRONICS, INC. has no way of controlling the use of this equipment
or of choosing the personnel to operate it, and therefore cannot take steps to comply with laws
pertaining to product liability, including laws which impose a duty to warn the user of any dangers
involved in operating this equipment. Therefore, acceptance of this system by the customer shall be
conclusively deemed to include a covenant by the customer to defend, indemnify, and hold SEA-BIRD
ELECTRONICS, INC. harmless from all product liability claims arising from the use or servicing of
this system.
2
Page 3
Manual revision 005 Declaration of Conformity SBE 63
Declaration of Conformity
3
Page 4
Manual revision 005 Table of Contents SBE 63
Table of Contents
Limited Liability Statement ............................................................................2
Declaration of Conformity ..............................................................................3
Table of Contents .............................................................................................4
Section 1: Introduction ....................................................................................5
About this Manual ............................................................................................ 5
Quick Start ........................................................................................................ 5
Unpacking SBE 63 ............................................................................................ 6
Section 2: Description of SBE 63 ....................................................................7
System Description ........................................................................................... 7
Specifications .................................................................................................... 8
Dimensions and Connector ............................................................................... 9
Section 3: Preparing SBE 63 for Deployment ............................................. 10
Software Installation ....................................................................................... 10
Power and Communications Test ................................................................... 10
Test Setup ................................................................................................. 10
Test ........................................................................................................... 11
Section 4: Deploying and Operating SBE 63 ............................................... 16
Sampling Modes ............................................................................................. 16
Polled Sampling ........................................................................................ 16
Autonomous Sampling ............................................................................. 18
Command Descriptions ................................................................................... 20
Data Formats ................................................................................................... 27
Deployment ..................................................................................................... 29
Integration with SeaCAT CTD
(SBE 16plus V2, 16plus-IM V2, or 19plus V2) ....................................... 29
Integration with MicroCAT CTD
(SBE 37-SMP-ODO, 37-IMP-ODO, 37-SIP-ODO) ................................. 30
Recovery ......................................................................................................... 31
Section 5: Routine Maintenance and Calibration ....................................... 32
Corrosion Precautions ..................................................................................... 32
Connector Mating and Maintenance ............................................................... 32
Sensor Maintenance ........................................................................................ 33
Sensor Calibration ........................................................................................... 34
Section 6: Troubleshooting ............................................................................ 35
Problem 1: Unable to Communicate with SBE 63 .......................................... 35
Problem 2: Unreasonable Data ....................................................................... 35
Glossary .......................................................................................................... 37
Appendix I: Functional Description ............................................................. 38
Appendix II: Installation/Removal from Optional Sensor Mount ............ 42
Appendix III: Command Summary ............................................................. 43
Appendix IV: Replacement Parts ................................................................. 44
Appendix V: Manual Revision History ........................................................ 45
Index................................................................................................................ 46
4
Page 5
Manual revision 005 Section 1: Introduction SBE 63
Section 1: Introduction
This section includes a Quick Start procedure, and photos of a standard
SBE 63 shipment.
About this Manual
This manual is to be used with the SBE 63 Digital Optical Dissolved Oxygen
Sensor. It is organized to guide the user from installation through operation
and data collection. We’ve included detailed specifications, command
descriptions, maintenance and calibration information, and helpful notes
throughout the manual.
Sea-Bird welcomes suggestions for new features and enhancements of our
products and/or documentation. Please contact us with any comments or
suggestions ([email protected] or 425-643-9866). Our business hours are
Monday through Friday, 0800 to 1700 Pacific Standard Time (1600 to 0100
Universal Time) in winter and 0800 to 1700 Pacific Daylight Time (1630 to
0000 Universal Time) the rest of the year.
Quick Start
Follow these steps to get a Quick Start using the SBE 63.
The manual provides step-by-step details for performing each task:
1. Perform pre-check procedures (see Section 3: Preparing SBE 63
for Deployment):
A. Test power and communications.
2. Deploy the SBE 63 (see Section 4: Deploying and Operating SBE 63):
A. Establish setup and operating parameters.
B. Check status (GetSD) and calibration coefficients (GetCC) to verify
setup.
C. Install I/O cable connector and locking sleeve, and mount SBE 63.
D. Deploy SBE 63.
5
Page 6
Manual revision 005 Section 1: Introduction SBE 63
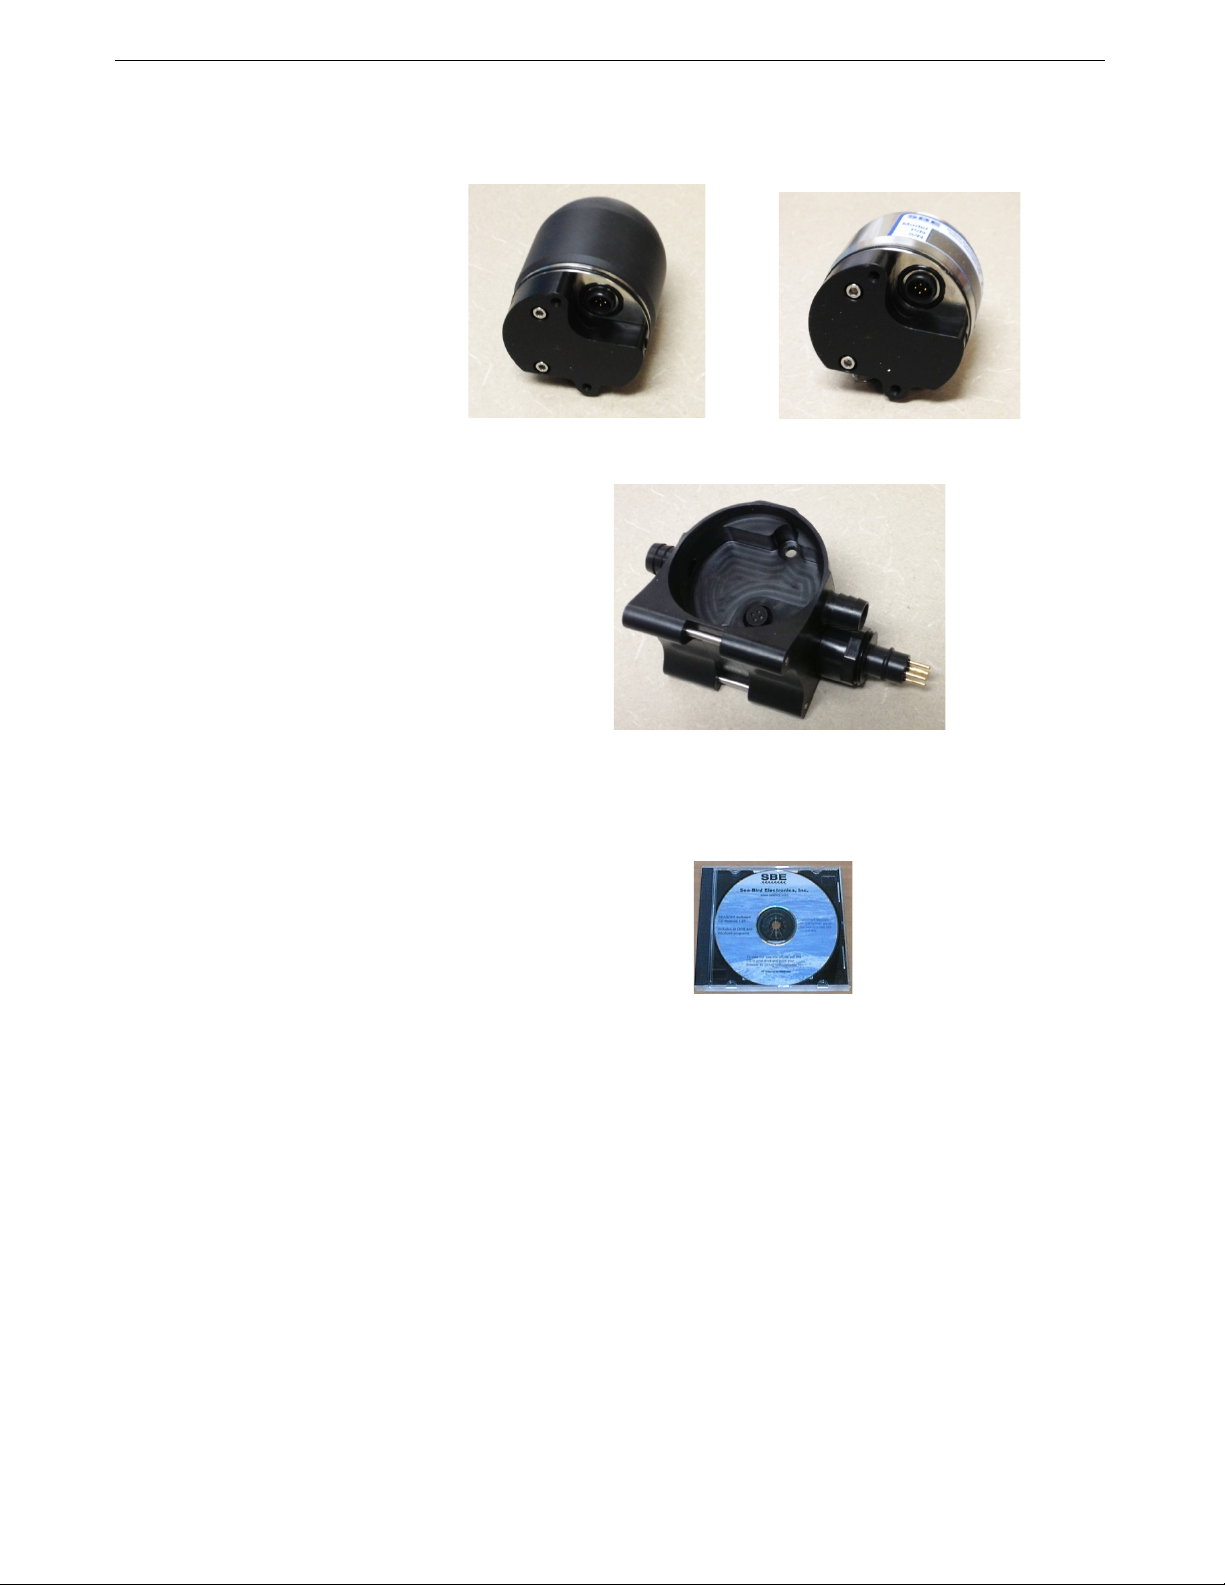
Software, and Electronic Copies of
Optional sensor mount for installation on
SBE 63 (titanium housing)
Unpacking SBE 63
Shown below is a typical SBE 63 shipment.
SBE 63 (plastic housing)
OR
SBE 16plus V2, 16plus-IM V2, or 19plus V2
Software Manuals and User Manual
6
Page 7
Manual revision 005 Section 2: Description of SBE 63 SBE 63
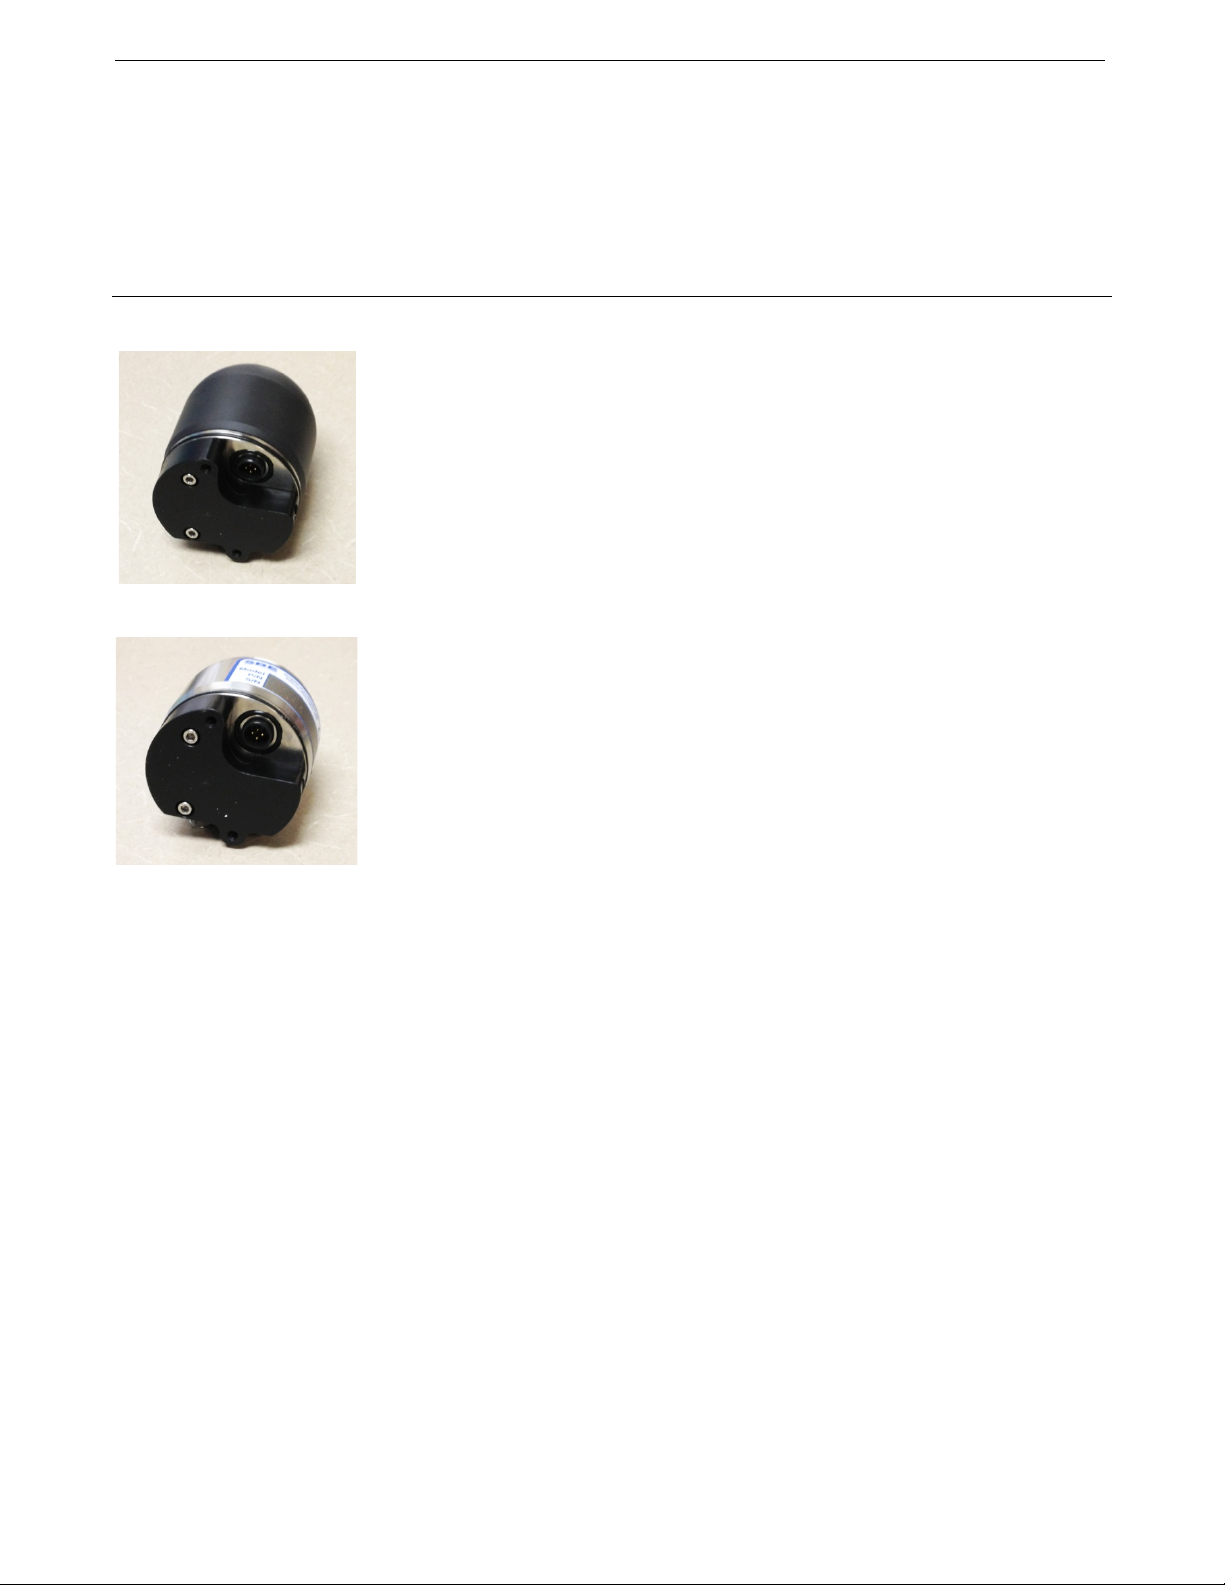
SBE 63 (plastic housing)
Section 2: Description of SBE 63
This section describes the functions and features of the SBE 63, including
specifications and dimensions.
System Description
The SBE 63 is an easy-to-use, light, compact instrument ruggedly made of
titanium and other low-maintenance (plastic) materials, designed to be
incorporated into oceanographic sensing systems at depths up to 600 or
7000 meters (1960 or 23,000 feet). Commands sent to the SBE 63 provide
status display, data acquisition setup, and diagnostic tests. Its data is
telemetered by its internal, 3-wire, RS-232C interface. The SBE 63 has no
sample memory or internal batteries.
The SBE 63 samples in two modes:
• Autonomous sampling –The SBE 63 samples at pre-programmed
intervals of 1 to 32,767 seconds. It can be set to average up to
255 measurements per sample, and transmits the averaged data.
The SBE 63 can be programmed to begin autonomous sampling when
power is applied or on command.
• Polled sampling – On command, the SBE 63 takes one sample and
transmits the data.
The SBE 63 outputs raw or converted (ASCII engineering units) data in one of
a number of formats, for compatibility with existing CTDs.
Each SBE 63 is calibrated individually in a temperature-controlled bath.
Bath temperatures are varied at each of 4 oxygen values, providing a
SBE 63 (titanium housing)
comprehensive 24-point calibration. Two reference sensors in each bath are
standardized against Winkler titrations. Response time tests are conducted on
each sensor, using gas. Salinity and pressure impacts on sensor response are
each checked at two separate points.
The SBE 63 is designed for use in a CTD's pumped flow path. Water does not
freely flow through the plumbing between samples, allowing anti-foul
concentration inside the system to maintain saturation and eliminating
exposure of the sensor to light, maximizing bio-fouling protection. The
elapsed time between the CTD and associated oxygen measurement is easily
quantified, and corrected for in post-processing.
Configuration options:
• With the optional sensor mount, the SBE 63 can be plugged into the
RS-232 auxiliary sensor connector of the SBE 16plus V2, 16plus-IM V2,
or 19plus V2 SeaCAT CTD. Configuration choices include a 600-meter
plastic housing or 7000-meter titanium housing, and an XSG or
wet-pluggable MCBH connector.
• The SBE 63 with a 600-meter plastic or 7000-meter titanium housing can
be integrated into an SBE 37 MicroCAT (37-IMP-ODO, 37-SMP-ODO,
or 37-SIP-ODO).
• On an SBE 41 (Argo float) CTD, the SBE 63 has a 7000-meter titanium
housing. The SBE 63 is physically integrated with the CTD; however,
electronic operation of the SBE 63 requires an RS-232 interface in the
float controller.
7
Page 8
Manual revision 005 Section 2: Description of SBE 63 SBE 63
τ
Notes:
The SBE 63 is supplied with a powerful Windows software package,
Seasoft V2, which includes:
• Help files provide detailed
information on the software.
• A separate software manual on CDROM contains detailed information
on the setup and use of Seasave V7
and SBE Data Processing.
• Sea-Bird supplies the current
version of our software when you
purchase an instrument. As software
revisions occur, we post the revised
software on our FTP site. See our
website (www.seabird.com) for the
latest software version number, a
description of the software changes,
and instructions for downloading the
software from the FTP site.
• SeatermV2 - terminal program for communication and data retrieval.
SeatermV2 is a launcher, and launches the appropriate terminal program
for the selected instrument (Seaterm232 for RS-232 instruments such as
this SBE 63).
• Seasave V7 – program for acquiring, converting, and displaying real-time
or archived raw data.
• SBE Data Processing – program for calculation and plotting of
conductivity, temperature, pressure, auxiliary sensor data (such as
dissolved oxygen), and derived variables such as salinity and sound
velocity.
Specifications
Measurement
Range
120% of surface saturation in all natural waters,
fresh and salt
Initial Accuracy
Resolution
Sample-Based
Drift
Response Time
(
, 63%
response)
Sampling
Speed
Calibration
Input Power
Output Signal
Depth rating,
housing, and
weight (in air)
Larger of ±3 µmol/kg (equivalent to 0.07 ml/L or 0.1 mg/L)
or ±2%
0.2 µmol/kg
< 1 µmol/kg / 100,000 samples (20 °C)
< 6 sec (20 °C)
1 Hz (1 sample/sec)
Each sensor fully and individually calibrated
(0 – 450 µmol/kg oxygen, 0 – 30 °C, 0 – 35 psu,
0 – 2000 dbars)
8 coefficients plus 4 temperature compensation
coefficients
6 - 24 VDC, 35 mA (0.08 J/sample)
RS-232, 600-115,200 baud (user-selectable),
8 data bits, no parity, 1 stop.
Sensor:
600 m (1960 ft) plastic housing: 245 g (0.54 lbs)
7000 m (16,400 ft) titanium housing: 270 g (0.60 lbs)
Optional sensor mount
SBE 16plus V2, 16plus-IM V2, or 19plus V2: 225 g (0.50 lbs)
for use with
8
Page 9
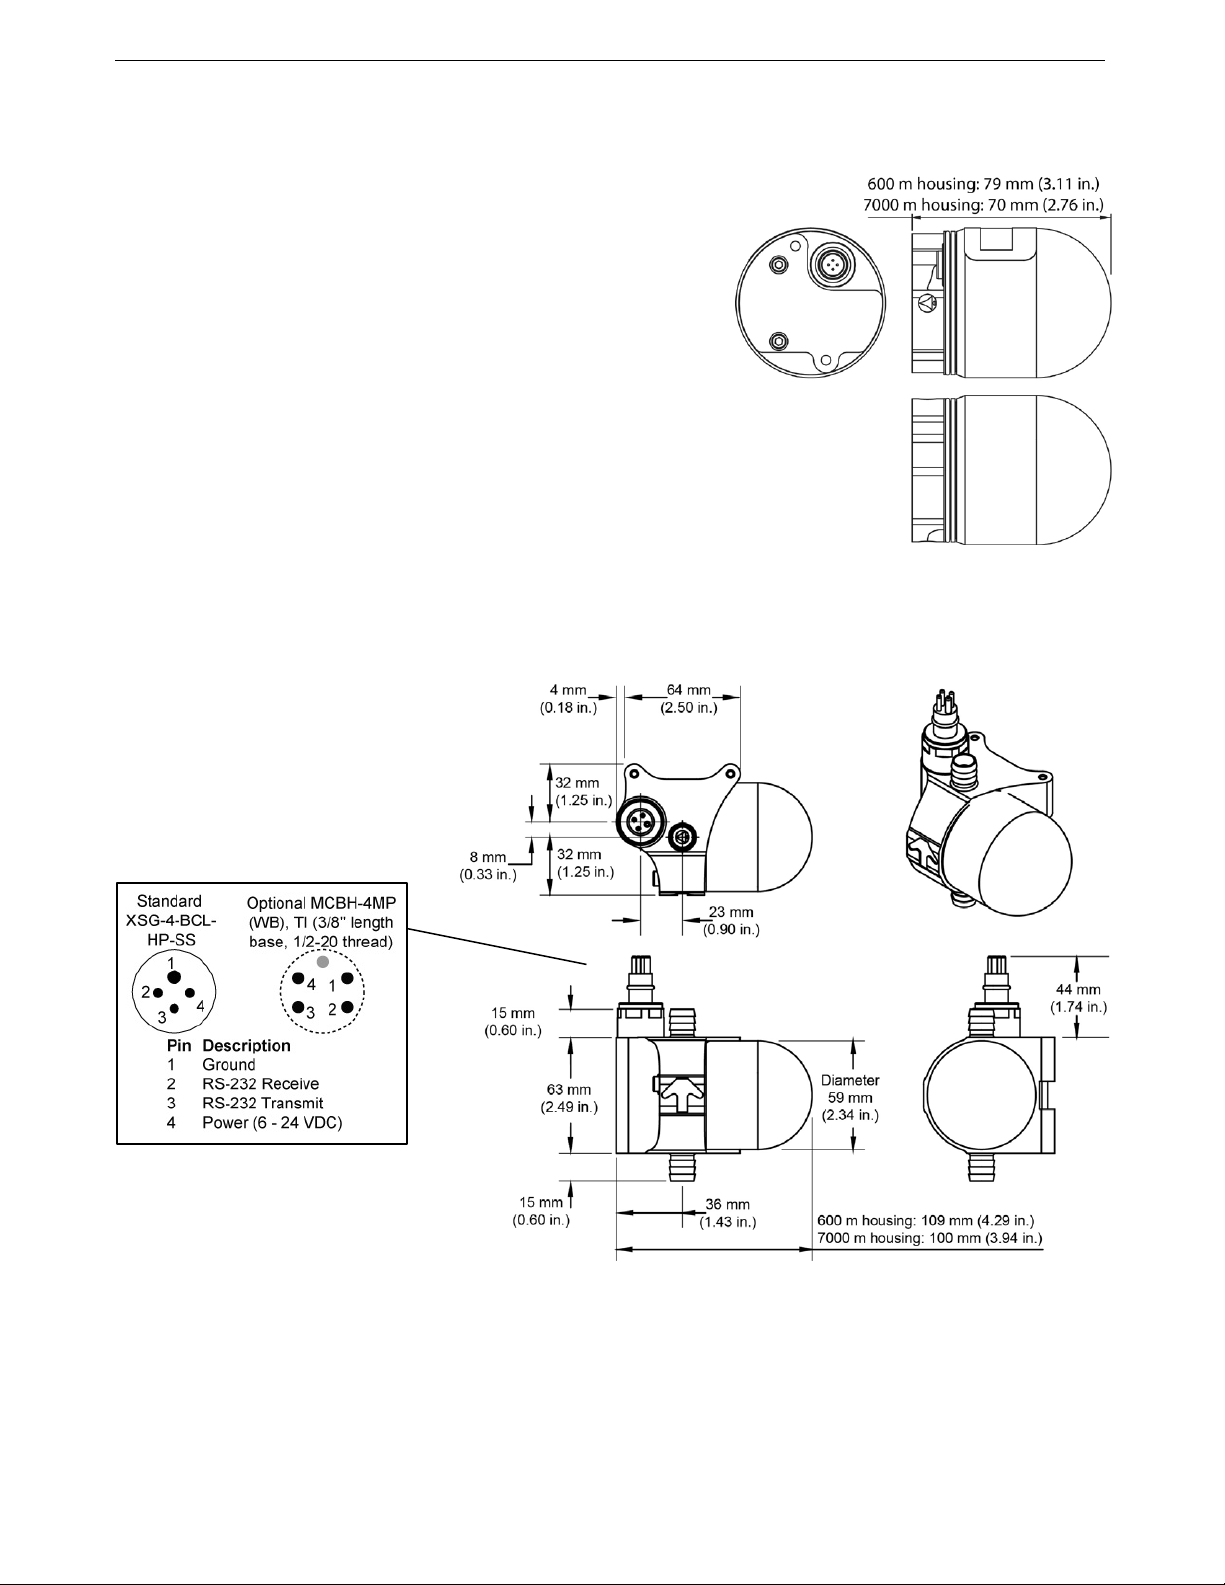
Manual revision 005 Section 2: Description of SBE 63 SBE 63
SBE 63 sensor installed in sensor
19plus V2 SeaCAT)
SBE 41 (Argo) CTD (7000 m housing)
Dimensions and Connector
SBE 63 sensor for integration with
SBE 37 ODO MicroCAT (600 m or 7000 m housing), or
mount, for use with RS-232
auxiliary sensor channel on CTD
(SBE 16plus V2, 16plus-IM V2, or
9
Page 10
Manual revision 005 Section 3: Preparing SBE 63 for Deployment SBE 63
Notes:
software from the FTP site.
Locking sleeve
Note:
SBE 63 through the MicroCAT.
Section 3: Preparing SBE 63 for Deployment
This section describes installing software and testing power and
communications.
Software Installation
Seasoft V2 was designed to work with a PC running Windows XP service
• Help files provide detailed
information on the software.
• It is possible to use the SBE 63
without the SeatermV2 terminal
program by sending direct
commands from a dumb terminal or
terminal emulator, such as Windows
HyperTerminal.
• Sea-Bird supplies the current
version of our software when you
purchase an instrument. As software
revisions occur, we post the revised
software on our FTP site. See our
website (www.seabird.com) for the
latest software version number, a
description of the software changes,
and instructions for downloading the
pack 2 or later, Windows Vista, or Windows 7.
If not already installed, install SeatermV2 and other Sea-Bird software
programs on your computer using the supplied software CD:
1. Insert the CD in your CD drive.
2. Install software: Double click on SeasoftV2.exe. Follow the dialog box
directions to install the software. The installation program allows you to
install the desired components. Install all the components, or just install
SeatermV2, Seasave V7, and SBE Data Processing.
The default location for the software is c:\Program Files\Sea-Bird. Within that
folder is a sub-directory for each program.
Power and Communications Test
SBE 63 integrated with a MicroCAT
(37-SMP-ODO, IMP-ODO, SIP-ODO):
See the MicroCAT manual for
information on communicating with the
I/O cable
The power and communications test will verify that the system works,
prior to deployment.
Test Setup
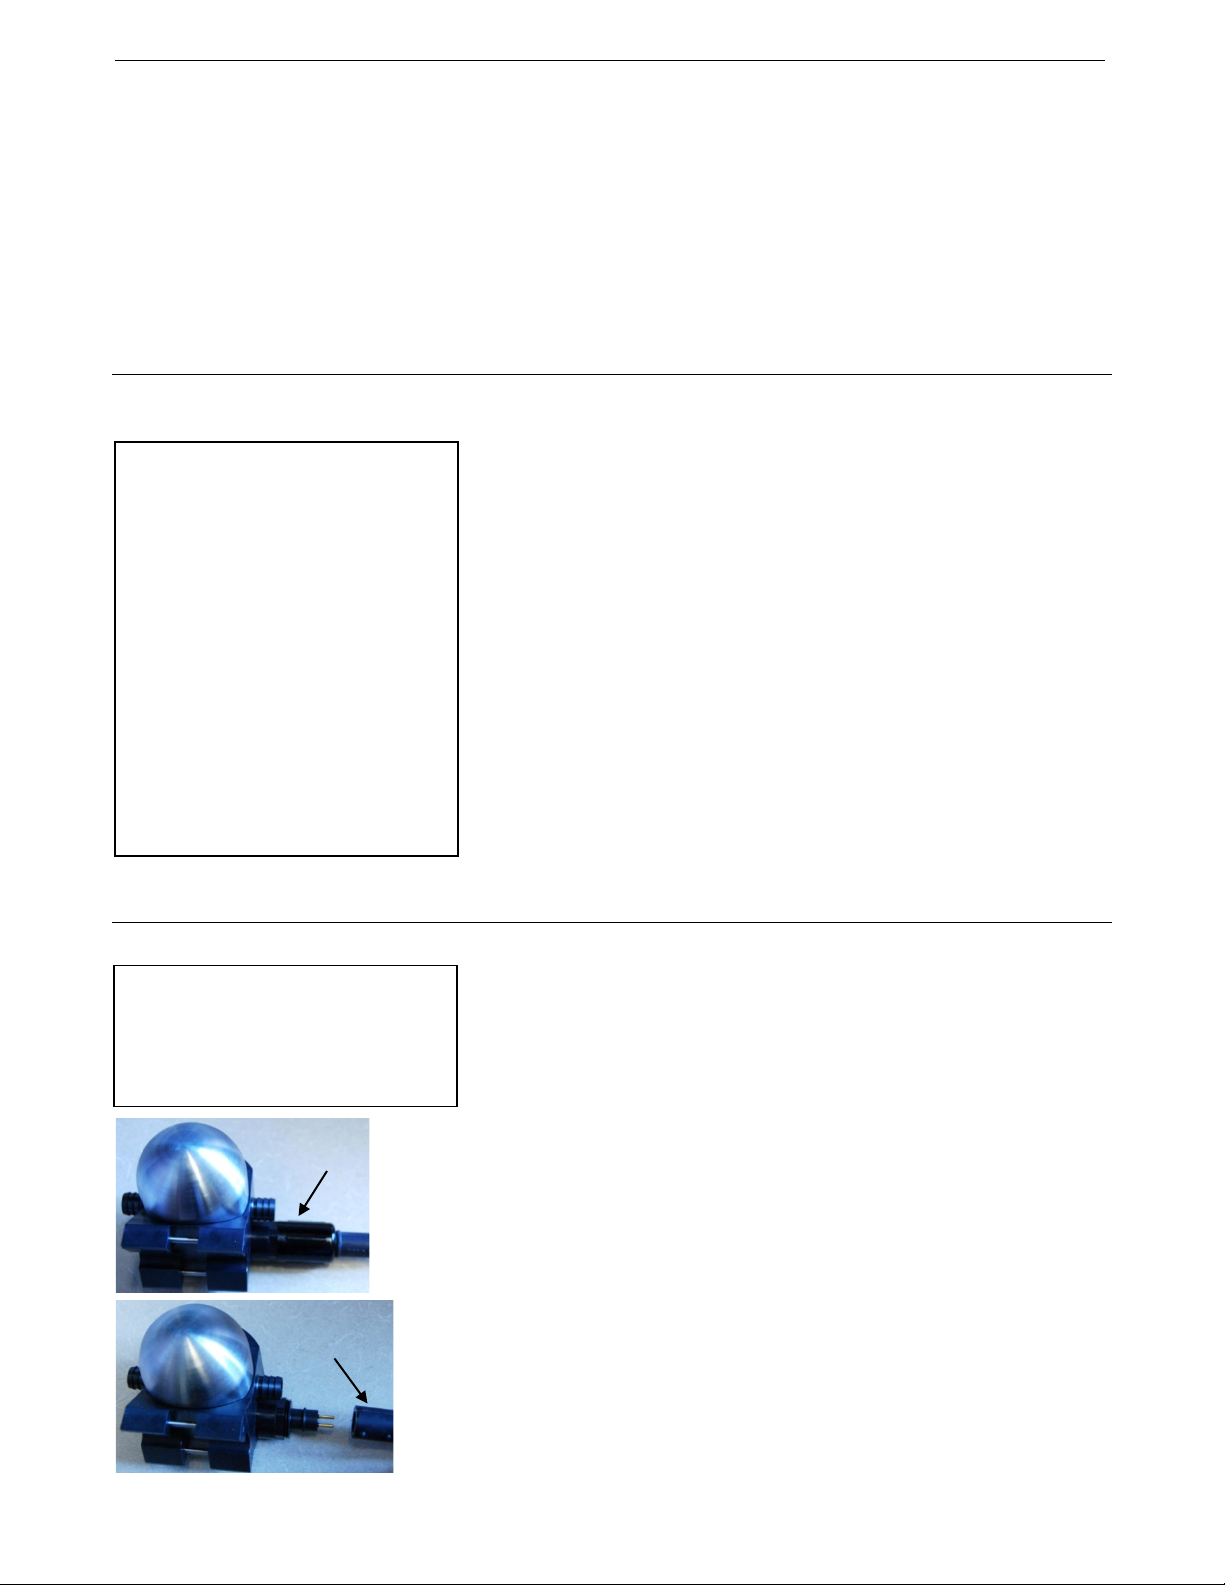
1. Remove dummy plug (if applicable):
2. Standard Connector - Install the I/O cable connector, aligning the raised
3. Connect the I/O cable connector to your computer’s serial port.
4. Connect the I/O cable connector’s red (+) and black (-) wires to a power
A. By hand, unscrew the locking sleeve from the SBE 63’s bulkhead
connector. If you must use a wrench or pliers, be careful not to
loosen the bulkhead connector instead of the locking sleeve.
B. Remove the dummy plug from the SBE 63’s I/O bulkhead connector
by pulling the plug firmly away from the connector.
bump on the side of the connector with the large pin (pin 1 - common) on
the SBE 63 sensor mount. OR
MCBH Connector – Install the I/O cable connector, aligning the pins.
supply (6 – 24 VDC).
10
Page 11
Manual revision 005 Section 3: Preparing SBE 63 for Deployment SBE 63
Notes:
Note:
Capture
Status –
Status Bar
Command/Data Echo Area
Send Commands
Test
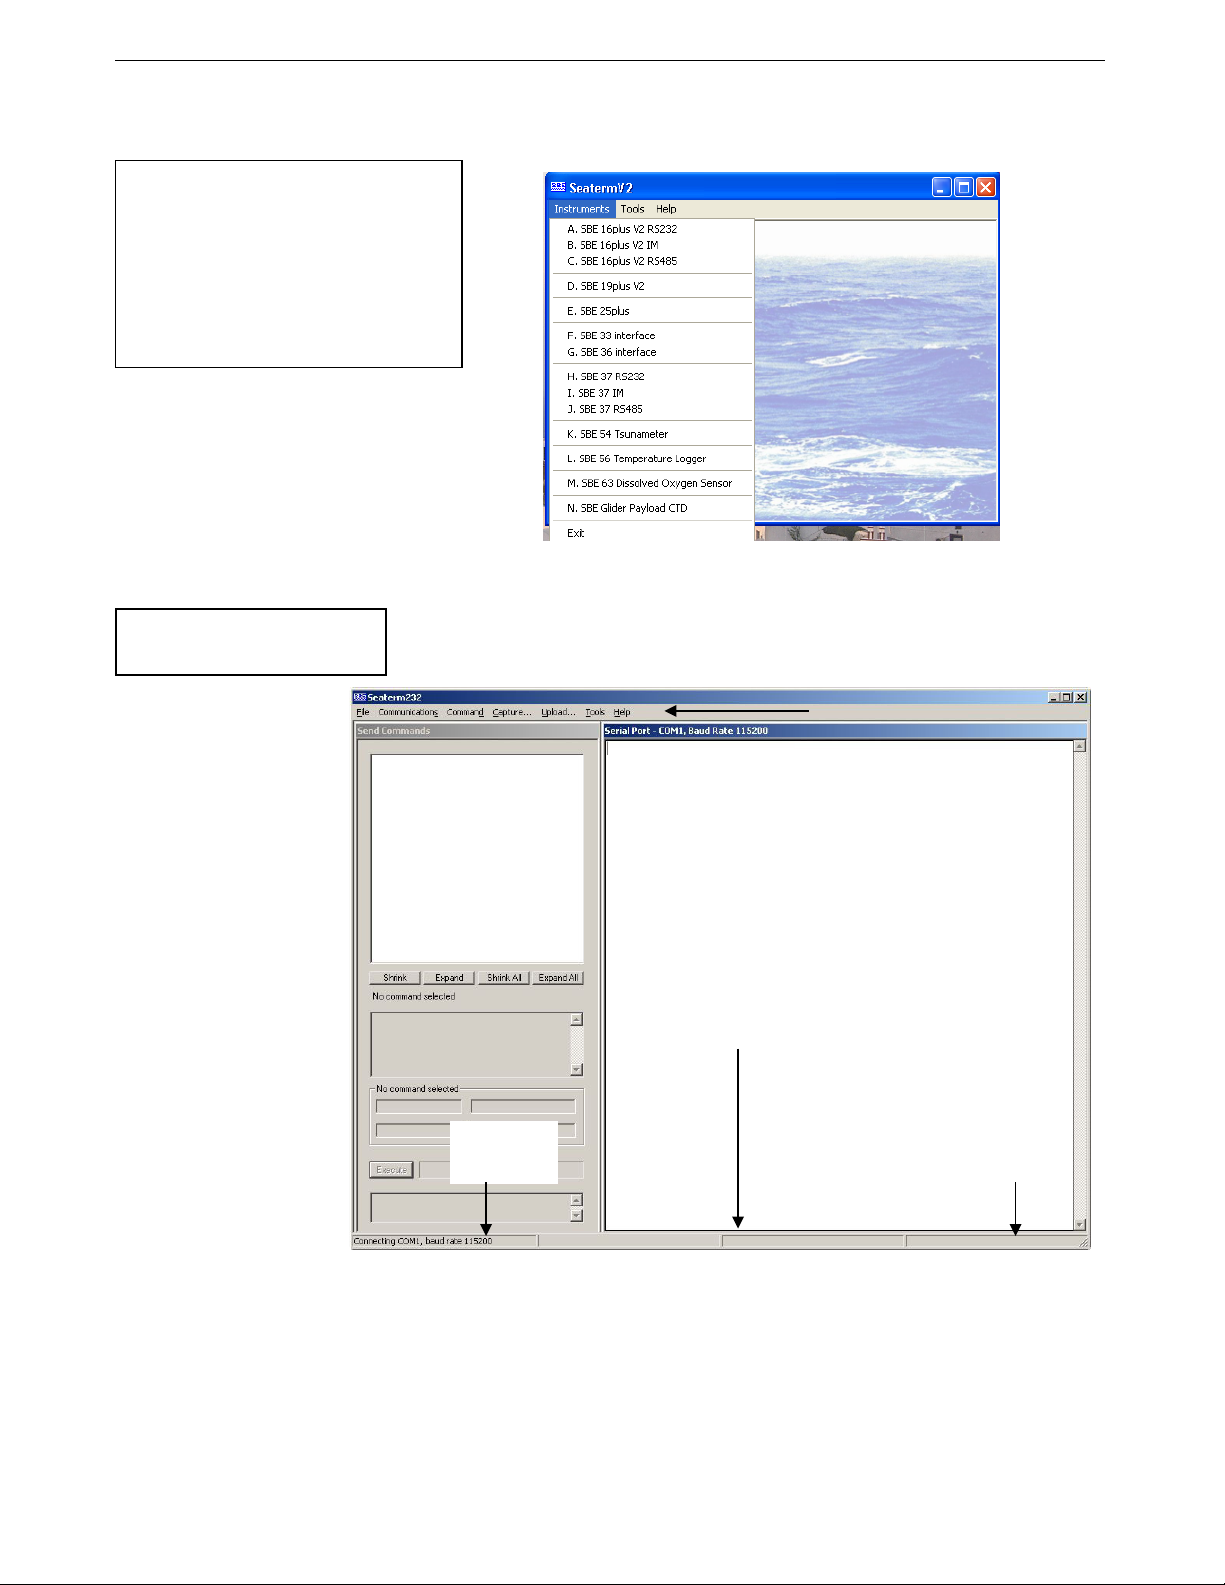
1. Double click on SeatermV2.exe. The main screen looks like this:
• You can use any terminal
program to set up the SBE 63;
set it to 8 data bits, no parity,
1 stop bit, and 9600 baud (default
SBE 63 baud rate). Instructions
here are for using SeatermV2.
See SeatermV2’s Help files.
•
SeatermV2 is a launcher. Depending on the instrument selected, it
launches Seaterm232 (RS-232 instruments), Seaterm485 (RS-485
instruments), or SeatermIM (inductive modem instruments).
See Seaterm232’s Help files.
2. In the Instruments menu, select SBE 63 Dissolved Oxygen Sensor.
Seaterm232 opens; the main screen looks like this:
Window
Connecting,
Ready, etc.
Menus
status
• Menus – For tasks and frequently executed instrument commands.
• Send Commands window – Contains commands applicable to your
SBE 63. The list appears after you connect to the SBE 63.
• Command/Data Echo Area – Title bar of this window shows
Seaterm232’s current comm port and baud rate. Commands and the
SBE 63 responses are echoed here. Additionally, a command can be
manually typed or pasted (ctrl + V) here. Note that the SBE 63 must
be connected and awake for it to respond to a command.
• Status bar – Provides connection, script, and capture status
information.
11
Page 12
Manual revision 005 Section 3: Preparing SBE 63 for Deployment SBE 63
Menu
Description
Equivalent Command*
• Load command file – opens selected .XML
Exit - Exit program.
• Connect – connect to comm port
if SBE 63 has stopped responding
• Abort – interrupt and stop SBE 63
SBE 63
• (press Esc key)
Capture SBE 63 responses on screen to file,
Upload
Not applicable to SBE 63
—
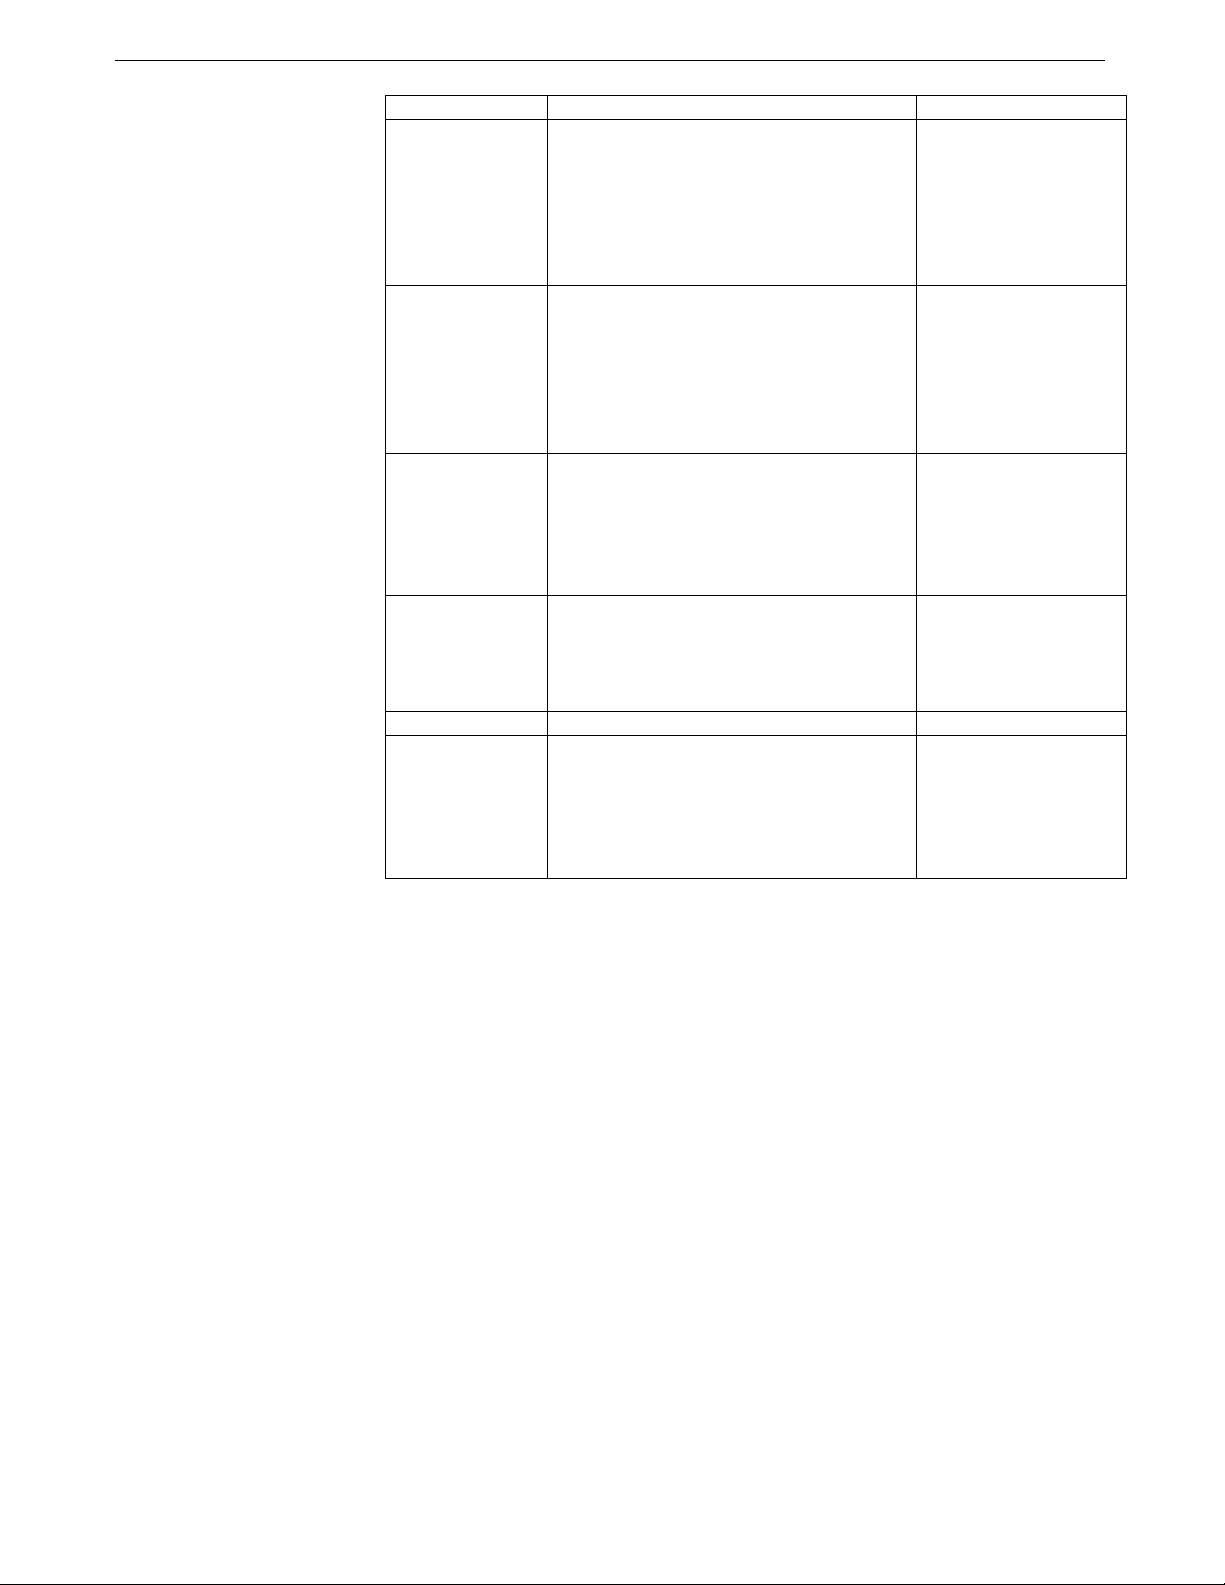
Following is a description of the menus:
command file, and fills Send Commands
window with commands
File
• Unload command file – closes command
—
file, and removes commands from Send
Commands window
•
• Disconnect – disconnect from
comm port
Communications
• Configure – Establish communication
—
parameters (comm port and baud rate).
• Disconnect and reconnect – may be useful
response
Command
• Send stop command
• Stop
Remaining menu items are not applicable to
to save real-time data or use for diagnostics.
Capture
File has .cap extension.
—
Click Capture again to turn off capture.
Capture status displays in Status bar.
• Diagnostics log - Keep a diagnostics log.
• Convert .XML data file – not applicable to
Tools
SBE 63
• Send script – Send XML script to SBE 63.
May be useful if you have a number of
SBE 63s to program with same setup.
*See Command Descriptions in Section 4: Deploying and Operating
SBE 63.
—
12
Page 13
Manual revision 005 Section 3: Preparing SBE 63 for Deployment SBE 63
Note:
Computer COM port and baud rate for
cycle through all available baud rates.
Update COM Port pulldown to
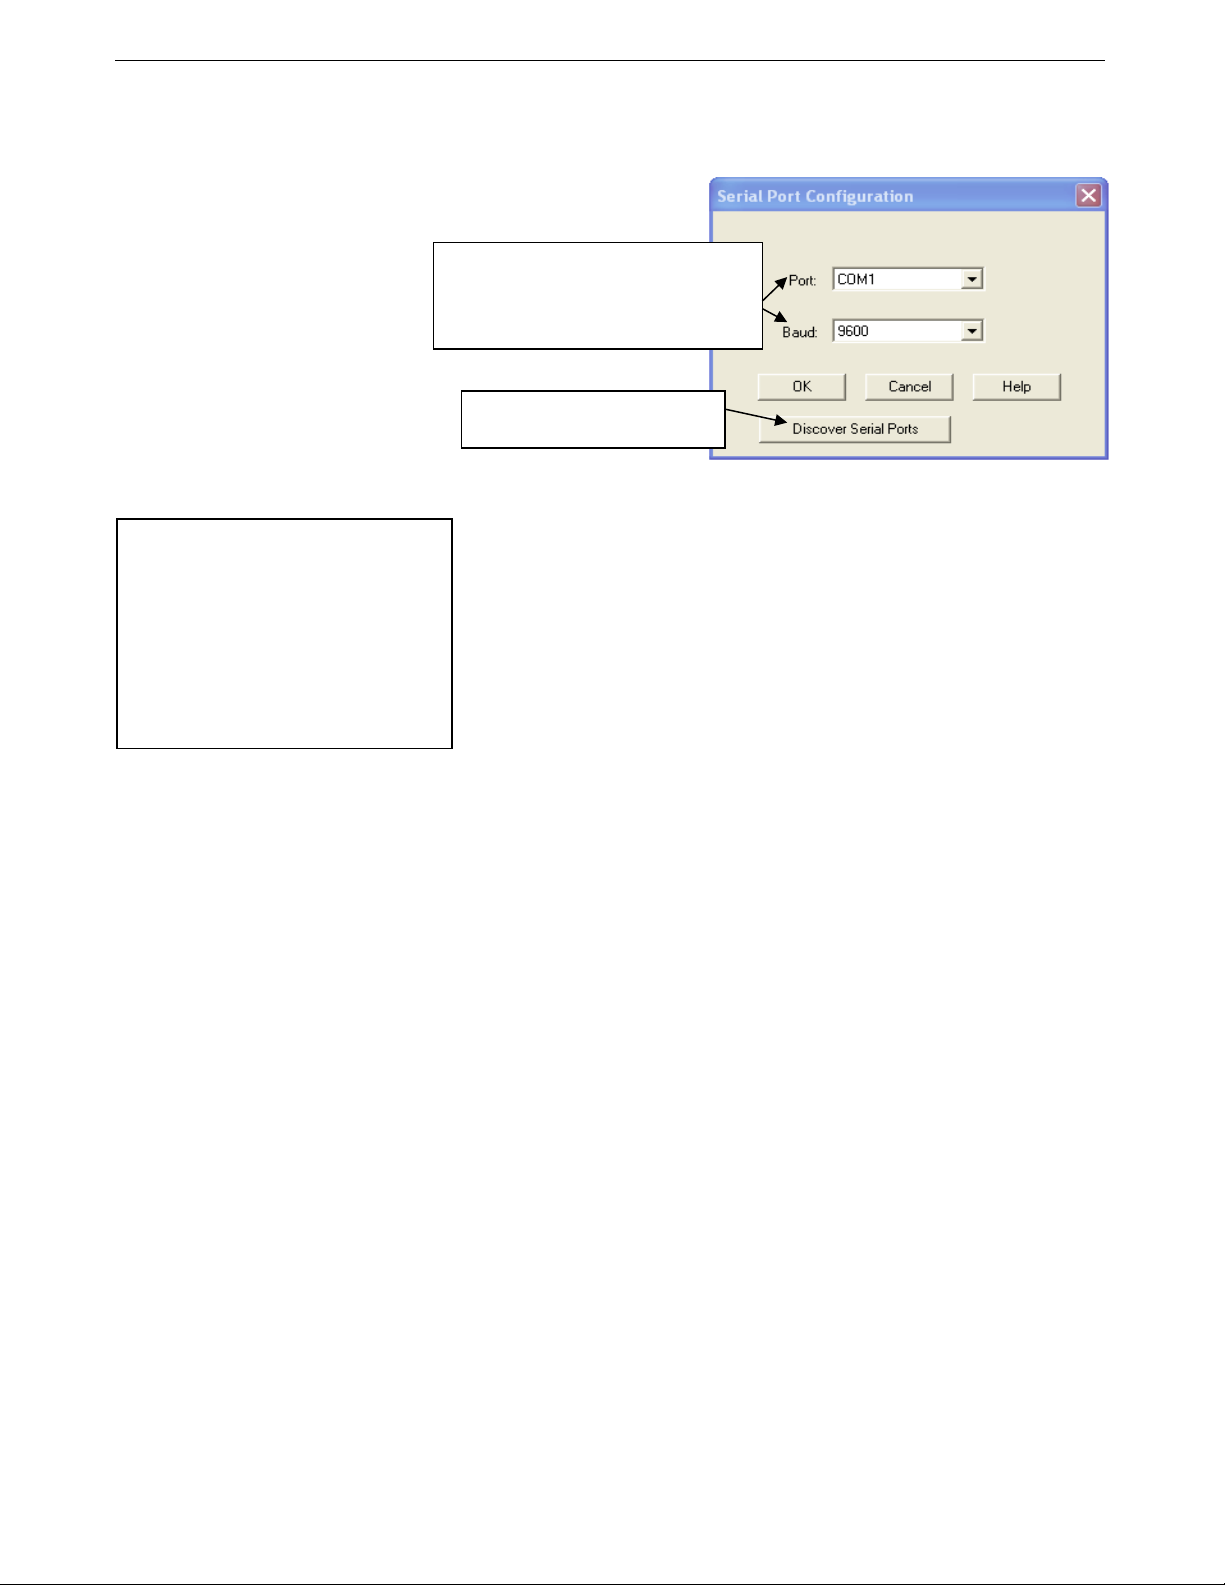
3. If this is the first time Seaterm232 is being used, the Serial Port
Configuration dialog box displays:
communication between computer and
SBE 63. Seaterm232 tries to connect at
this baud rate, but if unsuccessful will
include connected USB ports.
Make the desired selections, and click OK.
Seaterm232’s baud rate must be the
same as the SBE 63 baud rate (set
with SetBaud=). Baud is factory-set
to 9600, but can be changed by the
user (see Command Descriptions in
Section 4: Deploying and Operating
SBE 63). Other communication
parameters – 8 data bits, 1 stop bit,
and no parity – cannot be changed.
4. Seaterm232 tries to automatically connect to the SBE 63. As it connects,
it sends GetHD and displays the response, which provides factory-set
data such as instrument type, serial number, and firmware version.
Seaterm232 also fills the Send Commands window with the correct list
of commands for your SBE 63.
If there is no communication:
A. In the Communications menu, select Configure. The Serial Port
Configuration dialog box appears. Select the Comm port and baud
rate for communication, and click OK. Note that the factory-set baud
rate is documented on the Configuration Sheet. .
B. In the Communications menu, select Connect (if Connect is grayed
out, select Disconnect and reconnect). Seaterm232 will attempt to
connect at the baud specified in Step A, but if unsuccessful will then
cycle through all other available baud rates.
C. If there is still no communication, check cabling between the
computer and SBE 63, and try to connect again.
D. If there is still no communication, repeat Step A with a different
comm port, and try to connect again.
After Seaterm232 displays the GetHD response, it provides an S> prompt
to indicate it is ready for the next command.
13
Page 14
Manual revision 005 Section 3: Preparing SBE 63 for Deployment SBE 63
Click on desired command
Help box describes
Click Execute when ready
This box
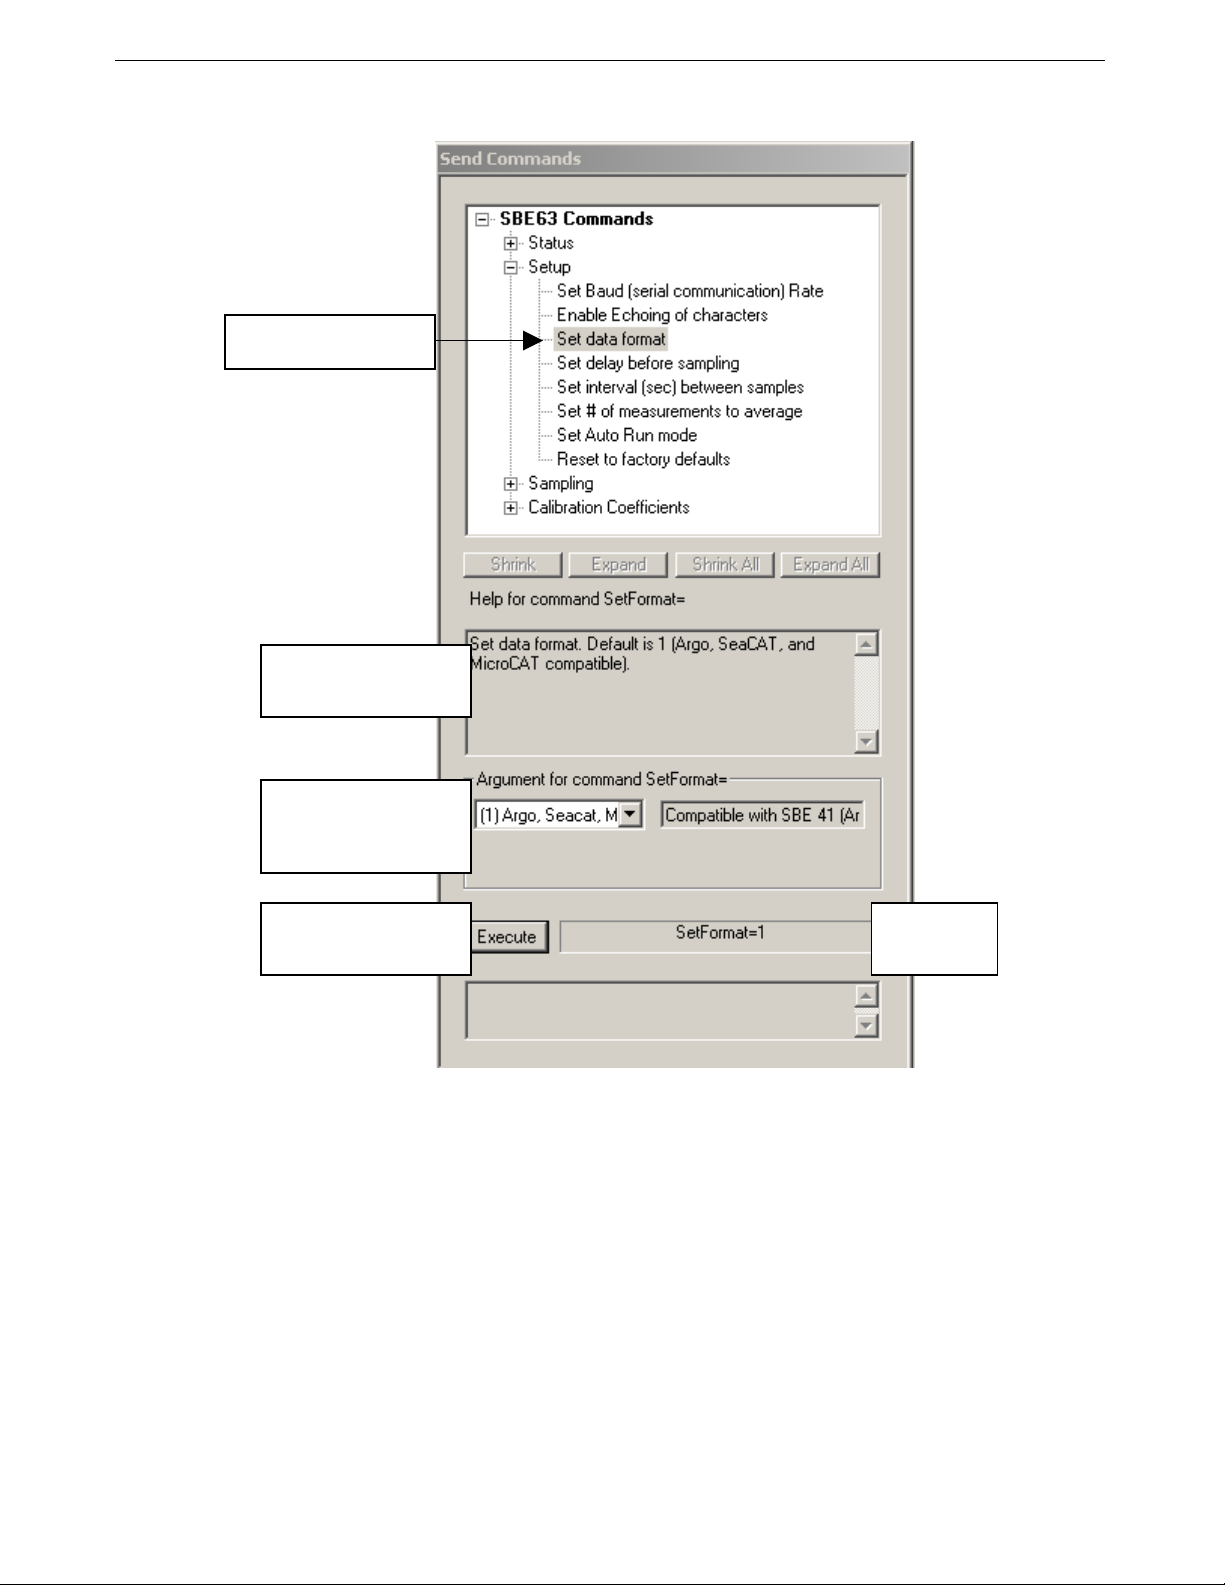
Taking a look at the Send Commands window:
description in list.
selected command in more
detail.
Enter any command
arguments (such as
desired output format) in
this box.
to send selected
command.
shows selected
command.
You can use the Send Commands window to send commands, or simply type
the commands in the Command/Data Echo area if desired.
14
Page 15
Manual revision 005 Section 3: Preparing SBE 63 for Deployment SBE 63
5. Display SBE 63 setup and hardware information by typing GetHD and
pressing the Enter key. The display looks like this:
<HardwareData DeviceType = 'SBE063' SerialNumber = '0013'>
<Manufacturer>Sea-Bird Electronics, Inc.</Manufacturer>
<FirmwareVersion>3.0.1</FirmwareVersion>
<FirmwareDate>Apr 9 2013 10:30:28</FirmwareDate>
<CommandSetVersion>1.2</CommandSetVersion>
<MFGDate>04142</MFGDate>
<PCBAssembly>41755</PCBAssembly>
<PCBSerialNum>00013</PCBSerialNum>
<PCBAssembly>41756</PCBAssembly>
<PCBSerialNum>00013</PCBSerialNum>
<FilmSerialNum>00077</FilmSerialNum>
<Supply Voltage>8.63</Supply Voltage>
<LoaderVersion>SBE 63 FirmwareLoader V 1.0</LoaderVersion>
<CalibrationDate>04826</CalibrationDate>
<HardwareConfig>
<BaudRate>009600</BaudRate>
<BlueOnTime>0000000</BlueOnTime>
<SampleAvg>002</SampleAvg>
<SampleInterval>00004</SampleInterval>
<BootDelay>001</BootDelay>
<OutFormat>01</OutFormat>
<AnalogGain>2</AnalogGain>
<AnalogOffset>00</AnalogOffset>
<AutoRun>0</AutoRun>
<BlueTupdate>0</BlueTupdate>
<SerPause>1</SerPause>
<Echo>1</Echo>
<Flags>0x0023</Flags>
</HardwareConfig>
</HardwareData>
6. Command the SBE 63 to take a sample by typing TS and pressing the
Enter key. The display looks like this (if SBE 63 is set up with
SetFormat=1):
16.411,0.550736,5.980,25.0011
where 16.411 = raw phase delay
0.550736 = raw thermistor voltage
5.980 = converted oxygen in ml/l
25.0011 = temperature in deg C
The SBE 63 is ready for programming and deployment.
15
Page 16
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Example 1: Polled Sampling (user input in bold).
Notes:
Note:
Section 4: Deploying and Operating SBE 63
This section provides instructions for deploying the SBE 63. It includes:
Separate software manuals and
Help files contain detailed
information on installation, setup,
and use of Sea-Bird’s software.
Sampling Modes
• Sea-Bird ships the SBE 63 with
SetAutoRun=0 (it will not
automatically start sampling when
power is applied). If you previously
sent SetAutoRun=1 (it
automatically started sampling
when power was applied), press the
Esc key to stop sampling. You will
then be able to send commands to
change the setup.
• SBE 63 response to commands is
not shown in examples.
• Sampling modes, including example sets of commands
• Command descriptions
• Data output formats
• Deployment
• Recovery
The SBE 63 has two sampling modes for obtaining data:
• Polled Sampling
• Autonomous Sampling
Shown below are descriptions and examples of the two sampling modes. Note
that the SBE 63’s response to each command is not shown in the examples.
Review the operation of the sampling modes and the commands described in
Command Descriptions before setting up your system.
Polled Sampling
On command (TS or TSR), the SBE 63 takes one sample of data and transmits
the data.
Set up to wait for a command upon power up (SetAutoRun=0). Set up to
echo commands (SetEcho=1), output converted oxygen and temperature
data (SetFormat=0), and average 2 measurements/sample (SetAvg=2).
Verify setup with status (GetHD) command. Remove power.
(Apply power, then select Connect in Seaterm232’s Communications
menu to connect and wake up.)
S>SETAUTORUN=0
S>SETECHO=1
S>SETFORMAT=0
S>SETAVG=2
S>GETHD (to verify setup)
(Remove power.)
When ready to take a sample (repeat as desired): apply power, establish
communications with SBE 63, command it to take a sample and output
data in format established with SetFormat=, and remove power.
(Apply power, then select Connect in Seaterm232’s Communications
menu to connect and wake up.)
(Before first sample, click Capture menu to capture data to a file –
Seaterm232 requests file name for data to be stored.)
S>TS
(Remove power.)
Examples continued on next page
16
Page 17
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Example 2: Polled Sampling with SBE 16plus V2 (user input in bold).
(Apply power to SBE 63, then select Connect in Seaterm232’s
Note:
When using the SBE 63 with an
SBE 16plus V2, 16plus-IM V2, or
19plus V2 CTD, the following setup in
the SBE 63 is required:
• SetBaud= to the baud rate set in the
CTD (1200 for the 16plus-IM V2)
• SetEcho=1
• SetFormat=1
• SetAvg=1 to 16; recommended
value is 2
• SetAutoRun=0
In the CTD, set:
• Pump mode to 2 (PumpMode=2).
• Delay before sampling
(DelayBeforeSampling=) to
25 sec at 15 °C to 40 sec at 0 °C
(linear interpolation between those
values). This provides enough time
for the SBE 63 to equilibrate after
pumping begins, before the
measurement is made.
In the CTD, the interval between
samples (SampleInterval=) must be
greater than or equal to the sum of the
times required to sample. Total time is
affected by the following:
- Minimum time required for CTD to
take a sample (≈ 2.5 sec).
- Time required for integration of
optional Quartz pressure sensor
(ParosIntegration=).
- Time required for CTD to take and
average NCycles= samples; samples
are taken 0.25 sec apart.
- Delay after providing power to
external sensors before sampling
(DelayBeforeSampling=); described
above.
- Delay after sampling before turning
off power to external sensors
(DelayAfterSampling=).
For the 16plus-IM V2, commands are
preceded by #ii (ii=ID).
Set up to wait for a command upon power up (SetAutoRun=0). Set up to
echo commands (SetEcho=1), average 2 measurements per output sample
(SetAvg=2), and output data in a format compatible with 16plus V2
(SetFormat=1). Set SBE 63 baud rate to same baud as 16plus V2 (assume
9600 baud for this example). Verify setup with status (GetHD) command.
Remove power.
Communications menu to connect to and wake up SBE 63.)
S>SETAUTORUN=0
S>SETECHO=1
S>SETAVG=2
S>SETFORMAT=1
S>SETBAUD=9600 (get message to re-enter baud)
SB>SETBAUD=9600
(In Seaterm232’s Communications menu, select Configure. Change baud
to 9600 and click OK. In Seaterm232’s Communications menu, select
disconnect and reconnect. You will now be communicating at new baud).
S>GETHD (to verify setup)
(Remove power from SBE 63.)
When ready to begin sampling: Connect SBE 63 to 16plus V2 RS-232
auxiliary sensor connector. Start autonomous sampling in 16plus V2 (see
16plus V2 manual). Each time SBE 16plus V2 takes a measurement, it
applies power to and requests a sample from SBE 63 using TS command.
When ready to stop sampling: Stop autonomous sampling in 16plus V2.
Example 3: Polled Sampling with SBE 41 (Argo float) CTD that is not
making continuous oxygen measurements (user input in bold).
Set up to wait for a command upon power up (SetAutoRun=0). Set up to
echo commands (SetEcho=1), output raw and converted oxygen and
temperature data (SetFormat=1), to average 2 measurements/sample
(SetAvg=2). Verify setup with status (GetHD) command. Remove power.
(Apply power, then select Connect in Seaterm232’s Communications
menu to connect and wake up.)
S>SETAUTORUN=0
S>SETECHO=1
S>SETFORMAT=1
S>SETAVG=2
S>GETHD (to verify setup)
(Remove power.)
When ready to begin sampling: Connect SBE 63 to SBE 41. Each time
SBE 41 takes an oxygen measurement, it applies power to and requests a
sample from SBE 63 using TS command.
17
Page 18
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
To Start
0 (default)
Send Start.
Example 1: Autonomous Sampling Setup for SetAutoRun=0 (user
Note:
send Start.
Autonomous Sampling
The SBE 63 does not have an internal (standby) real-time clock. Therefore,
once you start autonomous sampling, power to the SBE 63 must remain on for
autonomous sampling to continue at the specified interval.
SetAutoRun defines how sampling starts:
Sea-Bird ships the SBE 63 with
SetAutoRun=0 (it will not
automatically start sampling when
power is applied). If you send
SetAutoRun=1, turn power off and
then on again to start sampling, or
SetAutoRun=
1
input in bold).
Set up to wait for a command upon power up (SetAutoRun=0).
Set up to echo commands (SetEcho=1), take and output a sample every
10 sec (SetInterval=10), averaging 2 measurements per output sample
(SetAvg=2), and output converted oxygen and temperature data
(SetFormat=0). Verify setup with status (GetHD) command. Remove
power.
(Apply power, then select Connect in Seaterm232’s Communications
menu to connect and wake up.)
S>SETAUTORUN=0
S>SETECHO=1
S>SETINTERVAL=10
S>SETAVG=2
S>SETFORMAT=0
S>GETHD (to verify setup)
(Remove power.)
When ready to begin sampling:
(Apply power, then select Connect in Seaterm232’s Communications
menu to connect and wake up.)
S>START
When ready to stop sampling:
(Send Stop, click Esc, or remove power.)
Autonomous
Sampling
Turn on power.
To Stop Autonomous Sampling
• Turn off power, or
• Click Esc (stopping this way allows
you to then send commands to
check/modify the setup), or
• Send Stop (stopping this way allows
you to then send commands to
check/modify the setup).
Examples continued on next page
18
Page 19
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Example 2: Autonomous Sampling Setup for SetAutoRun=1 for use
with power supply and logger.
Set up to start sampling when power is applied (SetAutoRun=1).
Set up to echo commands (SetEcho=1), take samples at 10-sec intervals
(SetInterval=10), average 2 measurements per output sample
(SetAvg=2), output converted oxygen and temperature data
(SetFormat=0), and set the delay before sampling to the minimum value
(SetBootDelay=). Verify setup with status (GetHD) command. Remove
power.
(Apply power, then select Connect in Seaterm232’s Communications
menu to connect and wake up.)
S>SETAUTORUN=1
S>SETECHO=1
S>SETINTERVAL=10
S>SETAVG=2
S>SETFORMAT=0
S>SETBOOTDELAY=1
S>GETHD (to verify setup)
(Remove power from SBE 63.)
When ready to begin sampling, connect SBE 63 to power supply and data
logger.
(Apply power – SBE 63 automatically begins sampling at 10-sec
intervals.)
When ready to stop sampling:
(remove power.)
19
Page 20
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Command Descriptions
This section describes commands and provides sample outputs.
See Appendix III: Command Summary for a summarized command list.
When entering commands:
• Input commands to the SBE 63 in upper or lower case letters and register
commands by pressing the Enter key (0xD).
• Commands to enable a parameter can be entered with the argument as
Y or 1 for yes, and N or 0 for no (for example, SetAutoRun=y and
SetAutoRun=1 are equivalent; both enable automatic starting of sampling
when power is applied).
• The SBE 63 sends Command failed: Unknown command
if an invalid command is entered.
• If the SBE 63 does not return an S> prompt after executing a command,
press the Enter or Esc key to get the S> prompt.
• If the SBE 63 is transmitting data and you want to stop it, press the Esc
key or send Stop. Alternatively, remove power.
• All commands that change setup take effect immediately, and are
committed to nonvolatile storage (SBE 63 retains settings when power is
removed).
20
Page 21
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Example: (user input in bold)
Status Command
GetSD Get and display status data, which includes
all parameters related to setup of SBE 63
that can be input/modified. Many
parameters are not user-programmable,
and are programmed at the factory.
List and example below include
commands used to modify userprogrammable parameters:
• Instrument type and serial number
• Firmware version
• Software used to upload firmware to SBE
63
• Calibration date (days since
January 1, 2000)
• Communication baud rate [SetBaud=]
• Blue LED counter total on-time (sec)
• Number of measurements to average per
sample [SetAvg=]
• Interval between samples for autonomous
sampling [SetInterval=]
• Delay before sampling after power is
applied [SetBootDelay=]
• Data output format [SetFormat=]
• Analog gain and offset
• Begin sampling automatically when power
applied [SetAutoRun=]?
• Update Blue LED counter with every
sample?
• Serial pause (factory set; must be 1
for use with SBE 19plus V2 in Profiling
mode, 16plus-IM V2, or
37-IMP-ODO); can be 0 or 1 for other
integrations.
• Enable echoing [SetEcho=]?
• Internally calculated [based on settings]
S>getsd
<StatusData DeviceType = 'SBE063' SerialNumber = '0013'>
<FirmwareVersion>
<FirmwareDate>Apr 9 2013 10:30:28</FirmwareDate>
<CommandSetVersion>1.2</CommandSetVersion>
<LoaderVersion>SBE 63 FirmwareLoader V 1.0</LoaderVersion>
<CalibrationDate>04826</CalibrationDate>
<StatusConfig>
<BaudRate>009600</BaudRate> [SetBaud=]
<BlueOnTime>0000000</BlueOnTime>
<SampleAvg>002</SampleAvg> [SetAvg=]
<SampleInterval>00004</SampleInterval> [SetInterval=]
<BootDelay>001</BootDelay> [SetBootDelay=]
<OutFormat>01</OutFormat> [SetFormat=]
<AnalogGain>2</AnalogGain>
<AnalogOffset>00</AnalogOffset>
<AutoRun>0</AutoRun> [SetAutoRun=]
<BlueTupdate>0</BlueTupdate>
<SerPause>1</SerPause>
<Echo>1</Echo> [SetEcho=]
<Flags>0x0023</Flags> [internally calculated, based on SetAutoRun= and factory settings]
</StatusConfig>
</StatusData>
<Executed>
3.0.1</FirmwareVersion>
21
Page 22
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Example: (user input in bold)
<Executed>
Status Command (continued)
GetHD Get and display hardware data. Many
parameters are not user-programmable,
and are programmed at the factory. List
and example include commands used to
modify user-programmable parameters:
• Instrument type and serial number
• Manufacturer
• Firmware revision
• Firmware date
• Command set version
• Manufacture date
• PCB assembly and serial numbers
• Optical film serial number
• Power supply voltage seen by SBE 63
• Software used to upload firmware to SBE 63
• Calibration date (days since January 1, 2000)
• Communication baud [SetBaud=]
• Blue LED counter total on-time (sec)
• Number of measurements to average per
sample [SetAvg=]
• Interval between samples for autonomous
sampling [SetInterval=]
• Delay before sampling after power is applied
[SetBootDelay=]
• Data output format [SetFormat=]
• Analog gain and offset
• Begin sampling automatically when power
applied [SetAutoRun=]?
• Update Blue LED counter with each sample?
• Serial pause (factory set; must be 1 for use
with SBE 19plus V2 in Profiling mode,
16plus-IM V2, or 37-IMP-ODO); can be
0 or 1 for other integrations.
• Enable echoing [SetEcho=]?
• Internally calculated [based on settings]
S>gethd
<HardwareData DeviceType = 'SBE063' SerialNumber = '0013'>
<Manufacturer>Sea-Bird Electronics, Inc.</Manufacturer>
<FirmwareVersion>3.0.1</FirmwareVersion>
<FirmwareDate>Apr 9 2013 10:30:28</FirmwareDate>
<CommandSetVersion>1.2</CommandSetVersion>
<MFGDate>04142</MFGDate>
<PCBAssembly>41755</PCBAssembly>
<PCBSerialNum>00013</PCBSerialNum>
<PCBAssembly>41756</PCBAssembly>
<PCBSerialNum>00013</PCBSerialNum>
<FilmSerialNum>00077</FilmSerialNum>
<Supply Voltage>8.63</Supply Voltage>
<LoaderVersion>SBE 63 FirmwareLoader V 1.0</LoaderVersion>
<CalibrationDate>04826</CalibrationDate>
<HardwareConfig>
<BaudRate>009600</BaudRate> [SetBaud=]
<BlueOnTime>0000000</BlueOnTime>
<SampleAvg>002</SampleAvg> [SetAvg=]
<SampleInterval>00004</SampleInterval> [SetInterval=]
<BootDelay>001</BootDelay> [SetBootDelay=]
<OutFormat>01</OutFormat> [SetFormat=]
<AnalogGain>2</AnalogGain>
<AnalogOffset>00</AnalogOffset>
<AutoRun>0</AutoRun> [SetAutoRun=]
<BlueTupdate>0</BlueTupdate>
<SerPause>1</SerPause>
<Echo>1</Echo> [SetEcho=]
<Flags>0x0023</Flags> [internally calculated, based on SetAutoRun= and factory settings]
</HardwareConfig>
</HardwareData>
22
Page 23
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Example: (user input in bold)
<Executed>
Status Command (continued)
GetCC Get and display calibration coefficients,
which are initially factory-set and should
agree with Calibration Certificate shipped
with SBE 63. Example below includes,
where applicable, command used to
modify parameter.
• <CalDate> is number of days since
January 1, 2000.
• SetRefSal= and SetRefP= are set by
user; see description below in
Calibration Coefficients section of
these command descriptions
S>getcc
<CalibrationCoefficients DeviceType = 'SBE063' SerialNumber = '0013'>
<Calibration format = 'TEMP1' id = 'Temperature'>
<SerialNum>06300013</SerialNum>
<CalDate>04826</CalDate>
<TA0>+5.593530e-04</TA0> [SetTA0=]
<TA1>+2.756939e-04</TA1> [SetTA1=]
<TA2>-1.453041e-06</TA2> [SetTA2=]
<TA3>+1.535286e-07</TA3> [SetTA3=]
</Calibration>
<Calibration format = 'OX1' id = 'OptOxygen'>
<SerialNum>06300013</SerialNum>
<CalDate>04826/CalDate>
<A0>+8.900000e-01</A0> [SetA0=]
<A1>-1.520000e-03</A1> [SetA1=]
<A2>+0.000000e+00</A2> [SetA2=]
<B0>-1.820000e-01</B0> [SetB0=]
<B1>+1.086300e+00</B1> [SetB1=]
<C0>+1.737200e-01</C0> [SetC0=]
<C1>+6.545500e-03</C1> [SetC1=]
<C2>+8.945700e-05</C2> [SetC2=]
<E>-2.600000e-03</E> [SetE=]
<SOLB0>-6.245230e-03</SOLB0> [SetSolB0=]
<SOLB1>-7.376141e-03</SOLB1> [SetSolB1=]
<SOLB2>-1.034100e-02</SOLB2> [SetSolB2=]
<SOLB3>-8.170830e-03</SOLB3> [SetSolB3=]
<SOLC0>-4.886820e-07</SOLC0> [SetSolC0=]
<REFSALpsu>+0.000000e+00</REFSALpsu> [SetRefSal=]
<REFPRESSdbar>+0.000000e+00</REFPRESSdbar> [SetRefP=]
</Calibration>
</CalibrationCoefficients>
23
Page 24
Note:
Example: (user input in bold).
S>
Note:
preceded by #ii (ii=ID).
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Setup Commands
SetBaud=x x= baud rate (600, 1200, 2400, 4800,
When communicating directly with the
SBE 63, the SBE 63’s baud rate (set
with SetBaud=) must be the same as
Seaterm232’s baud rate (set in the
Communications menu).
9600, 19200, 33600, 38400, 57600, or
115200). Default 9600. Check capability
of your computer and terminal program
before increasing baud rate; high baud
rates require a short cable and good PC
serial port with accurate clock. SBE 63
requires you to enter command twice to
confirm.
When using the SBE 63 with an
SBE 16plus V2, 16plus-IM V2, or
19plus V2 CTD, the following setup in
the SBE 63 is required:
• SetBaud= to the baud rate set in the
CTD (1200 for the 16plus-IM V2)
• SetEcho=1
• SetFormat=1
• SetAvg=1 to 16; recommended
value is 2
• SetAutoRun=0
In the CTD, set:
• Pump mode to 2 (PumpMode=2).
• Delay before sampling
(DelayBeforeSampling=) to
25 sec at 15 °C to 40 sec at 0 °C
(linear interpolation between those
values). This provides enough time
for the SBE 63 to equilibrate after
pumping begins, before the
measurement is made.
In the CTD, the interval between
samples (SampleInterval=) must be
greater than or equal to the sum of the
times required to sample. Total time is
affected by the following:
- Minimum time required for CTD to
take a sample (≈ 2.5 sec).
- Time required for integration of
optional Quartz pressure sensor
(ParosIntegration=).
- Time required for CTD to take and
average NCycles= samples; samples
are taken 0.25 sec apart.
- Delay after providing power to
external sensors before sampling
(DelayBeforeSampling=); described
above.
- Delay after sampling before turning
off power to external sensors
(DelayAfterSampling=).
For the 16plus-IM V2, commands are
S>setbaud=19200
Baud change requested.
Re-enter setbaud command at OLD baudrate to confirm
SB>setbaud=19200
(may then show garbage characters, because of baud rate change)
(In Seaterm232’s Communications menu, select Configure. Change baud to 19200 and
click OK. In Seaterm232’s Communications menu, select Disconnect and reconnect).
(now communicating at 19200 baud)
SetEcho=x x=1: Echo characters received from
computer; monitor shows entered
commands as you type. Provides
compatibility with SBE 41 (Argo) CTD,
SeaCATs (16plus V2, 16plus-IM V2,
19plus V2), and MicroCATs (37-SMPODO, 37-IMP-ODO, 37-SIP-ODO)
x=0: Do not.
SetFormat=x Data output format (see Data Formats for
details):
x=0: Converted oxygen and temperature
(with units).
x=1: Raw phase delay and thermistor
voltage, converted oxygen and
temperature (no units), for compatibility
with SBE 41 (Argo) CTD, SeaCATs
(16plus V2, 16plus-IM V2, 19plus V2),
and MicroCATs (37-SMP-ODO,
x=2: Raw and converted data.
37-IMP-ODO, 37-SIP-ODO). Default.
x=3: Instrument name, serial number, and
converted oxygen.
SetBootDelay=x x= delay after power is applied before
sampling (1 - 255 sec). Default 1. Only
applicable if AutoRun=1.
SetInterval=x x= interval between samples
(1 – 32,767 sec) for autonomous sampling
(if power remains on, and Start has been
sent or AutoRun=1). Default 4.
24
Page 25
Note:
Note:
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Setup Commands (continued)
SetAvg=x x = number of measurements to take and
average per sample (1–64, or 1–32 for 1Hz
sampling); default 2. Each additional
measurement adds approximately 0.03 sec.
Increasing SetAvg= shortens sensor film
life and increases photo-bleaching effects.
Sea-Bird recommends SetAvg=2 for
best results, to prevent calibration shifts
caused by film heating and photo
bleaching-effects.
SetAutoRun=x x=0: Wait for command when power
To start autonomous sampling after
you send SetAutoRun=1:
• turn power off and then on again, or
• send Start or Go
applied. Default. Required setting for use
with SBE 41 (Argo) CTD, SeaCATs
(16plus V2, 16plus-IM V2, 19plus V2),
and MicroCATs (37-SMP-ODO,
37-IMP-ODO, 37-SIP-ODO)
x=1: Begin sampling when power applied.
First sample taken after SetBootDelay=.
*Default Reset most Setup parameters to their
factory defaults (SetFormat=,
SetBootDelay=, SetInterval=,
SetAvg=, SetAutoRun=).
Note that baud (SetBaud=) is not reset.
Sampling Commands
Start or Go Start autonomous sampling immediately at
rate set by SetInterval=, and output data
in format defined by SetFormat=.
Applicable if:
• SetAutoRun=0, or
• SetAutoRun=1, and you
previously clicked Esc to
stop sampling.
To stop sampling:
• Click Esc or send Stop command.
You may need to click Esc or send
Stop several times to get the SBE 63
to respond.
Once sampling is stopped and
terminal program shows S> prompt,
you can send desired commands
(setup, status, etc.).
OR
• Remove power.
Stop Stop autonomous sampling. Command
will not be echoed if autonomous sampling
is taking place. S> prompt appears to
signal that autonomous sampling has
stopped.
TS Take 1 sample and transmit data in format
defined by SetFormat=.
TSR Take 1 sample and transmit data in raw
format (for factory diagnostics).
25
Page 26
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Note:
Calibration Coefficients Commands
With the exception of SetRefSal= and SetRefP=, calibration coefficients are
initially factory-set and should agree with Calibration Certificate shipped with
the SBE 63.
SetCalDate=S S= calibration date (days since
January 1, 2000).
S = integer
F = floating point number
SetTA0=F F= TA0 coefficient.
SetTA1=F F= TA1 coefficient.
SetTA2=F F= TA2 coefficient.
SetTA3=F F= TA3 coefficient.
SetA0=F F= A0 coefficient.
SetA1=F F= A1 coefficient.
SetA2=F F= A2 coefficient.
SetB0=F F= B0 coefficient.
SetB1=F F= B1 coefficient.
SetC0=F F= C0 coefficient.
SetC1=F F= C1 coefficient.
SetC2=F F= C2 coefficient.
SetE=F F= E coefficient.
SetSolB0=F F= SolB0 coefficient.
SetSolB1=F F= SolB1 coefficient.
SetSolB2=F F= SolB2 coefficient.
SetSolB3=F F= SolB3 coefficient.
SetSolC0=F F= SolC0 coefficient.
SetRefSal=F F= Reference salinity (psu) to use for
oxygen calculation in converted units.
Default 0.
For moored application, enter approximate
value expected for deployment. For
profiling applications, enter 0, and correct
oxygen for salinity effect in postprocessing.
SetRefP=F F= Reference pressure (decibars) to use
for oxygen calculation in converted units.
Default 0.
For moored application, enter value
expected for deployment.
For profiling applications, enter 0, and
correct oxygen for pressure effect in postprocessing.
26
Page 27
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Notes:
Example: SetFormat=0
Example: SetFormat=1
, converted oxygen, converted
Data Formats
Note about units for converted oxygen:
Sea-Bird uses the following equations to convert oxygen to various
engineering units:
[mg/L] = [ml/L] * 1.42903
[micromole/Kg] = [ml/L] * 44660 / (sigma_theta(P,T,S) + 1000)
For the micromole/Kg conversion, there is disagreement in the scientific
community about the conversion constant 44660:
• The value 44660 is exact for oxygen gas.
• The value 44615 is the average value for atmospheric gas
(N2,O2,Ar,H2O,CO2,...). It is not exact for any individual gas, but has
been used historically by oceanographers.
The argument distills to exact versus historic, with oceanographers split;
Sea-Bird uses 44660 in all software calculations.
Following are the data formats:
• Each scan of data ends with a
carriage return and line feed.
• Converted oxygen values (dissolved
oxygen in ml/l) are dependent on the
user-set SetRefSal= and SetRefP=.
• See Appendix I: Functional
Description for details on the
calibration equation and conversion
of the raw data to dissolved oxygen
in ml/l.
• SetFormat=0 – Converted oxygen and temperature with units:
o.oooo ml/l, tt.tttt C
where
o.oooo = dissolved oxygen in ml/l
tt.tttt = temperature in deg C
4.3019 ml/l, 25.2556 C
(converted oxygen, converted temperature)
• SetFormat=1 (default) – SBE 41 (Argo) CTD, SeaCAT (16plus V2,
16plus-IM V2, 19plus V2), and MicroCAT (37-SMP-ODO,
37-IMP-ODO, 37-SIP-ODO) compatible:
aa.aaa, b.bbbbbb, o.oooo, tt.tttt where
aa.aaaa = raw phase delay (µsec)
b.bbbb = raw thermistor voltage
o.ooo = dissolved oxygen in ml/l
tt.tttt = temperature in deg C
16.6423,0.641321,4.308,25.2553
(raw phase delay, raw thermistor voltage
temperature)
27
Page 28
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Example: SetFormat=2
Example: SetFormat=3
• SetFormat=2 – Raw and converted data:
01/01/11 00:00:00 660 aaaaa 695 bbbbb 570 oooo ttttt
where
aaaaa = raw phase delay (x1000)
bbbbb = raw thermistor voltage (x65536/3.30)
oooo = dissolved oxygen in ml/l (x1000)
ttttt = temperature in deg C (x1000)
Italic numbers are constants, not used in calculations
Each field is separated by a tab character.
01/01/11 00:00:00 660 16649
695 12736 570 4303
25255
(information in italics are constants not used in calculations; remaining
information is raw phase delay x1000, raw thermistor voltage x1000, converted
oxygen x1000, converted temperature x1000)
• SetFormat=3 – Instrument name, serial number, and converted oxygen:
SBE63 ssss oo.ooo
where
ssss = SBE 63 serial number
oo.ooo = dissolved oxygen in ml/l (leading zero is not suppressed)
SBE63 and serial number are separated by a tab character; serial number
and dissolved oxygen are separated by two tab characters.
SBE63 0013 04.304
(serial number, converted oxygen in ml/l)
28
Page 29
Sensor mount –
Install
Note:
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Deployment
In the CTD, set:
• Pump mode to 2 (PumpMode=2).
• Delay before sampling
(DelayBeforeSampling=) to
25 sec at 15 °C to 40 sec at 0 °C
(linear interpolation between those
values). This provides enough time
for the SBE 63 to equilibrate after
pumping begins, before the
measurement is made.
In the CTD, the interval between
samples (SampleInterval=) must be
> the sum of the times required to
sample. Total time is affected by:
- Minimum time for CTD to take a
sample (≈ 2.5 sec).
- Time for integration of optional
Quartz pressure sensor
(ParosIntegration=).
- Time for CTD to take and average
NCycles= samples; samples are taken
0.25 sec apart.
- Delay after providing power to
external sensors before sampling
(DelayBeforeSampling=); described
above.
- Delay after sampling before turning
off power to external sensors
(DelayAfterSampling=).
For the 16plus-IM V2, commands are
preceded by #ii (ii=ID).
4-pin connector
Sensor mount
flow arrow
SBE 63 – 4-pin
connector
cap
screws
(2)
Integration with SeaCAT CTD (SBE 16plus V2, 16plus-IM V2, or 19plus V2)
Prior to installing the SBE 63 on the CTD, verify that the SBE 63 is set up as
follows (see Section 3: Preparing SBE 63 for Deployment for details on
communicating in Seaterm232; see Command Descriptions above for
command details):
• SetBaud= to baud rate set in CTD (always 1200 for 16plus-IM V2)
• SetEcho=1
• SetAvg=1 to 16; recommended value is 2
• SetFormat=1
• SetAutoRun=0
For use with the SBE 19plus V2 in Profiling mode, verify that <SerPause> in
the GetSD or GetHD response is 1 (factory set). For the 19plus V2 in Moored
mode, or for the other SeaCATs, <SerPause> can be set to 0 or 1.
Install on the CTD as follows:
1. Install the SBE 63 in the sensor mount:
A. Align the 4-pin connectors and push the SBE 63 onto the mount.
B. Install the two #10-24, 1/2” titanium cap screws from the back of the
sensor mount to secure the SBE 63 in the mount.
2. Mount the SBE 63 on the CTD. Install Tygon tubing to connect the
SBE 63 inline between the CTD conductivity cell outlet and the pump
inlet. Verify that the large arrow on the sensor mount is pointing in the
direction of the flow (flow enters through the conductivity cell, and exits
from the pump).
29
Page 30
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
CAUTION:
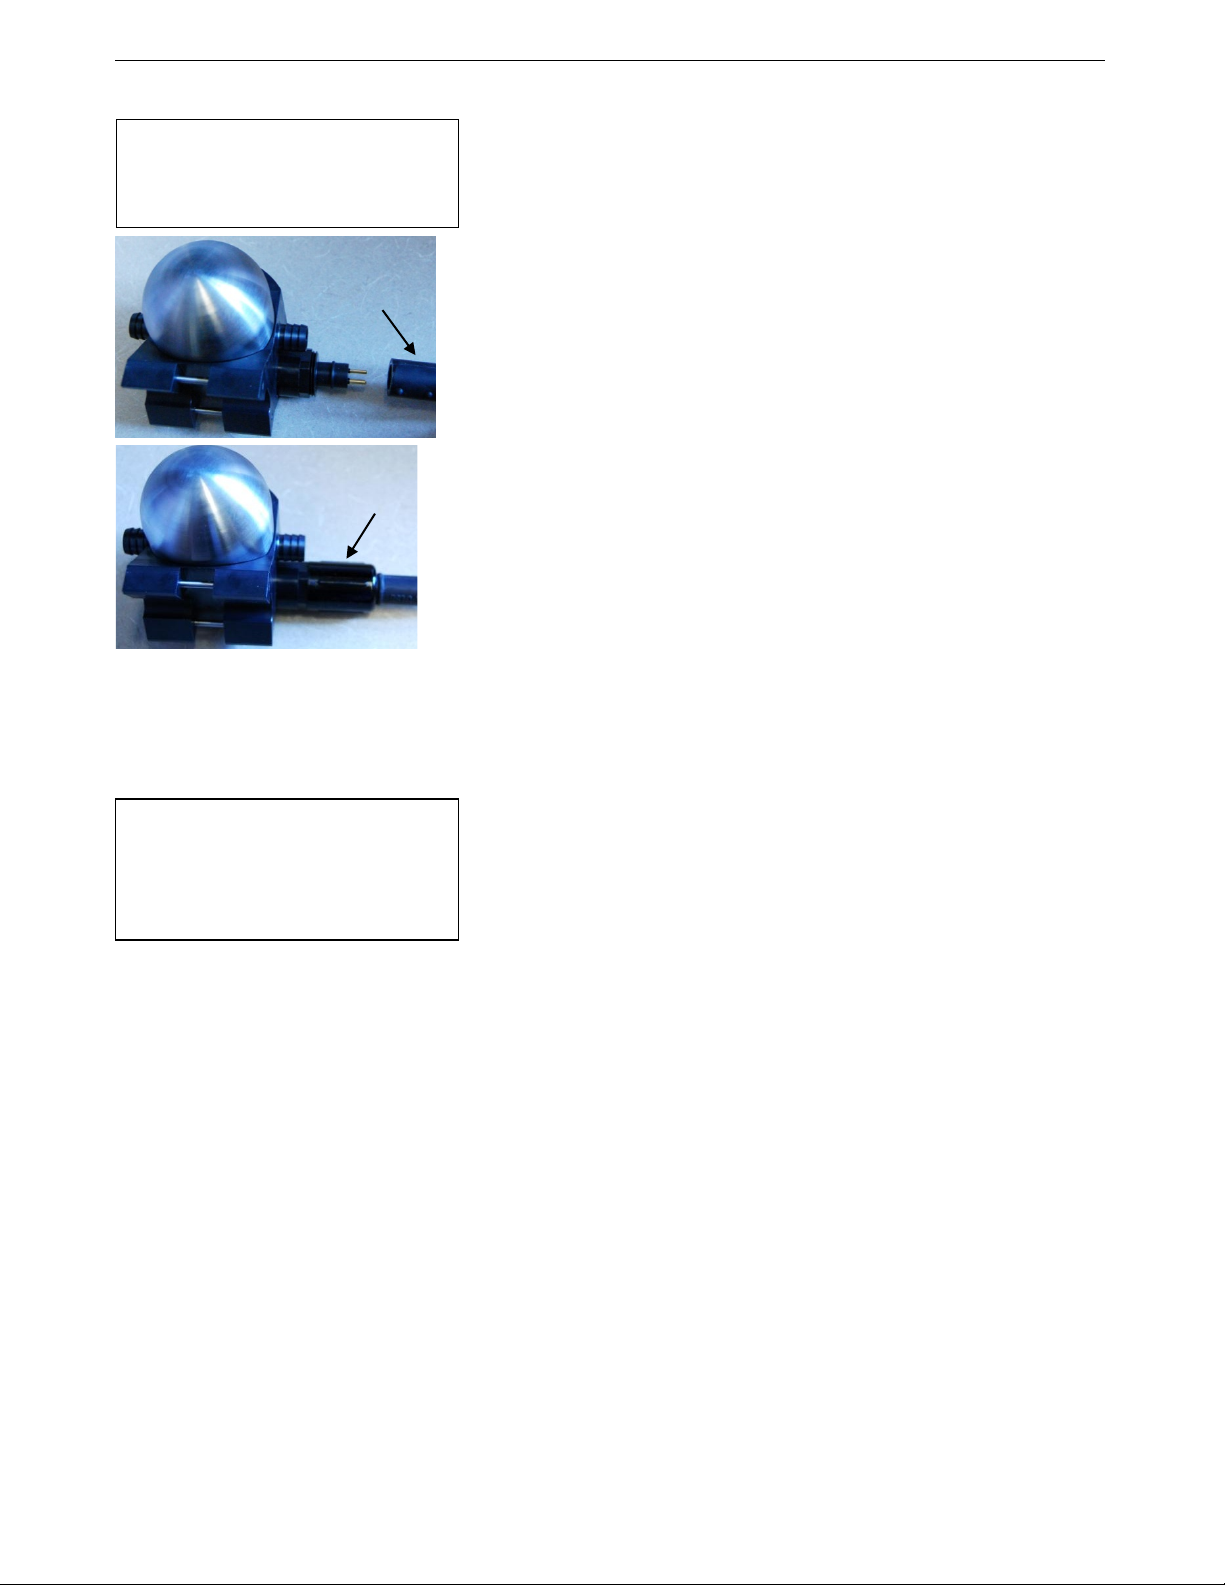
I/O cable
Locking sleeve
Note:
(for example, #01Send63=GetSD).
Do not use WD-40 or other petroleum-
based lubricants, as they will damage
the connector.
3. Install the I/O cable on the SBE 63 sensor mount:
A. Lightly lubricate the inside of the cable connector with silicone
grease (DC-4 or equivalent).
B. Standard Connector - Install the cable connector, aligning the raised
bump on the side of the connector with the large pin (pin 1 - ground)
on the SBE 63 sensor mount. Remove any trapped air by burping or
gently squeezing the connector near the top and moving your fingers
toward the end cap. OR
MCBH Connector – Install the cable connector, aligning the pins.
C. Place the locking sleeve over the connector. Tighten the locking
sleeve finger tight only. Do not overtighten the locking sleeve and
do not use a wrench or pliers.
4. Connect the I/O cable to the 4-pin RS-232 auxiliary sensor connector on
the CTD, using the same technique as in Step 3 (see the CTD manual for
the end cap detail).
5. Verify that the hardware and external fittings are secure.
The SBE 63 is ready to go into the water.
Integration with MicroCAT CTD (SBE 37-SMP-ODO, 37-IMP-ODO, 37-SIP-ODO)
The SBE 63 is factory-integrated with the ODO MicroCAT.
Precede Send63= with #ii (ii=
MicroCAT ID) for the 37-IMP-ODO
or the RS-485 versions of the
37-SMP-ODO and 37-SIP-ODO
You can communicate with the SBE 63 through the MicroCAT with
Send63=command; command can be any command recognized by the
SBE 63. Verify that the SBE 63 is set up as follows by sending
Send63=GetSD (see Command Descriptions above for command details):
• SetBaud=2400 (factory set; cannot be changed by command through the
MicroCAT)
• SetEcho=1
• SetAvg=1 to 16; recommended value is 2
• SetFormat=1
• SetAutoRun=0
For use with the SBE 37-IMP-ODO, 37-SMP-ODO with RS-485 interface,
and 37-SIP-ODO with RS-485 interface, verify that <SerPause> in the GetSD
or GetHD response is 1 (factory set). For the other MicroCATs, <SerPause>
can be set to 0 or 1.
30
Page 31
WARNING!
Manual revision 005 Section 4: Deploying and Operating SBE 63 SBE 63
Recovery
Rinse the outside of the SBE 63 with fresh water.
If the SBE 63 stops working while
underwater, is unresponsive to
commands, or shows other signs of
flooding or damage, carefully
secure it away from people until you
have determined that abnormal
internal pressure does not exist or
has been relieved. Pressure housings
may flood under pressure due to dirty
or damaged o-rings, or other failed
seals. When a sealed pressure
housing floods at great depths and is
subsequently raised to the surface,
water may be trapped at the pressure
at which it entered the housing,
presenting a danger if the housing is
opened before relieving the internal
pressure. Instances of such flooding
are rare. However, a housing that
floods at 6300 meters depth holds
an internal pressure of more than
7000 psia, and has the potential to
eject the end cap with lethal force.
A housing that floods at 63 meters
holds an internal pressure of more
than 85 psia; this force could still
cause injury.
If you suspect the SBE 63 is flooded,
point it in a safe direction away from
people. Remove the SBE 63 from the
sensor mount (if applicable). Very
slowly unscrew the SBE 63 dome,
letting the internal pressure bleed off
slowly past the O-ring as the O-ring is
released from the housing. Then, you
can safely remove the dome.
31
Page 32
Manual revision 005 Section 5: Routine Maintenance and Calibration SBE 63
CAUTION:
Note:
Section 5: Routine Maintenance and Calibration
This section reviews corrosion precautions, connector mating and
maintenance, sensor maintenance, and sensor calibration. The accuracy of the
SBE 63 is sustained by establishing proper handling practices.
Corrosion Precautions
Rinse the SBE 63 with fresh water after use and prior to storage.
All exposed metal is titanium; other materials are plastic. No corrosion
precautions are required, but direct electrical connection of titanium to
dissimilar metal hardware should be avoided.
Connector Mating and Maintenance
See Application Note 57: Connector
Care and Cable Installation for the
connection to the optional sensor
mount.
Do not use WD-40 or other
petroleum-based lubricants, as they
will damage the connector.
Optional Sensor Mount:
Clean and inspect the connectors, cable, and dummy plug before every
deployment and as part of your yearly equipment maintenance. Inspect
connectors that are unmated for signs of corrosion product around the pins,
and for cuts, nicks or other flaws that may compromise the seal.
When remating:
1. Lightly lubricate the inside of the cable connector with silicone grease
(DC-4 or equivalent).
2. Standard Connector - Install the cable connector, aligning the raised
bump on the side of the cable connector with the large pin
(pin 1 - ground) on the SBE 63. Remove any trapped air by burping or
gently squeezing the connector near the top and moving your fingers
toward the end cap. OR
MCBH Connector – Install the cable connector, aligning the pins.
3. Place the locking sleeve over the cable connector. Tighten the locking
sleeve finger tight only. Do not overtighten the locking sleeve and do
not use a wrench or pliers.
Verify that a cable is installed before deployment.
32
Page 33
CAUTIONS:
Manual revision 005 Section 5: Routine Maintenance and Calibration SBE 63
Sensor Maintenance
Procedures
Avoid fouling the optical window with oil or grease as this causes a
• During service and storage,
maintain temperatures between
ºC (32 – 104 ºF).
0 - 40
• Do not use stronger solutions or
longer wash times than
recommended.
• Do not place Triton or bleach
directly on the optical window.
calibration shift. An oil-fouled window can be cleaned using the following
procedures.
• Preventive Field Maintenance Between Profiles: After each cast, flush
with a 0.1% solution of Triton X-100, using a 60 cc syringe (see
Application Note 34). Then rinse thoroughly with fresh water. Between
casts, ensure that the sensor remains shaded from direct sunlight and stays
within the recommended temperature range.
• Routine (post-cruise) Cleaning (no visible deposits or marine growths
on sensor) -- Follow this two-step procedure:
1. Flush the sensor for 1 minute with a 1% solution of Triton X-100
warmed to 30 ºC (86 ºF). Drain and flush with warm (not hot) fresh
water for 5 minutes.
2. Soak the sensor for 1 minute in a 500 - 1000 ppm solution of Bleach.
After the soak, drain and flush with warm (not hot) fresh water for 5
minutes.
• Cleaning severely fouled sensors (visible deposits or marine growths
on sensor): Soak the sensor in de-ionized water overnight to loosen
deposits. Repeat the Routine Cleaning procedure up to 5 times. Do not
attempt to clean the optical window with high pressure flow or by wiping
or touching the window.
• Long-Term Storage (after field use): Do not fill the sensor with water,
Triton solution, or Bleach solution. Store dry.
o If there is danger of freezing, shake all excess water out of the
sensor. If in the optional sensor mount, loop tubing from inlet to
outlet, leaving the optical window dry.
Materials
• Triton X-100 - 100% Triton X-100 is included with every CTD shipment
and may be ordered from Sea-Bird; dilute as directed above. Triton X-100
is Octyl Phenol Ethoxylate, a mild, non-ionic surfactant (detergent), and is
manufactured by Avantor Performance Materials (see
http://avantormaterials.com/commerce/product.aspx?id=2147509608).
Other liquid detergents can probably be used, but scientific grades (with
no colors, perfumes, glycerins, lotions, etc.) are required.
• Bleach - Bleach is a common household product used to whiten and
disinfect laundry. Commercially available bleach is typically 4% - 7%
(40,000 – 70,000 ppm) sodium hypochlorite (Na-O-Cl) solution that
includes stabilizers. Some common commercial product names are Clorox
(U.S.) and eau de Javel (French).Clean the SBE 63 with a 500 - 1000 ppm
solution of water and sodium hypochlorite. Dilute the concentrated
household bleach to 50 to 1 (50 parts water to 1 part bleach) to produce
the proper concentration to clean the oxygen sensor.
• Water – We recommend de-ionized (DI) water because it is reliably pure,
but commercially distilled water or fresh clean tap water is also sufficient
for all uses above. On ships, fresh water can occasionally contain
traces of oil and should not be used for rinsing, cleaning, or storing
sensors, unless there is no alternative.
33
Page 34
Manual revision 005 Section 5: Routine Maintenance and Calibration SBE 63
Note:
Sensor Calibration
Each SBE 63 is calibrated individually in a temperature-controlled bath. Bath
See Appendix I: Functional Description
for details on the calibration equation.
temperatures are varied at each of 4 oxygen values, providing a comprehensive
24-point calibration. Two reference sensors in each bath are standardized
against Winkler titrations. Response time tests are conducted on each sensor,
using gas. Salinity and pressure impacts on sensor response are each checked
at two separate points
The SBE 63 calibration coefficients are printed on the Calibration Certificate
supplied with the sensor. These coefficients have also been stored in the
SBE 63, allowing the SBE 63 to directly output dissolved oxygen in ml/l.
When used on a Sea-Bird CTD (SBE 16plus V2, 16plus-IM V2, 19plus V2,
37-SMP-ODO, 37-IMP-ODO, 37-SIP-ODO), dissolved oxygen can be
calculated in other units in post-processing.
The primary mechanism for calibration drift in optical oxygen sensors is the
fouling of the optical window by chemical or biological deposits. Accordingly,
the most important determinant of long-term sensor accuracy is the cleanliness
of the window. We recommend that oxygen sensors be calibrated before and
after deployment, but particularly when the sensor has been exposed to
contamination by oil slicks or biological material.
Another important mechanism for oxygen sensor drift is photobleaching of the
sensor film. Keep the SBE 63 sensor film out of direct sunlight. Also, every
sample that is taken illuminates the film with short wavelength light that
eventually degrades the film. As a rule of thumb, re-calibration of the oxygen
sensor is recommended after 300,000 to500,000 samples.
34
Page 35
Manual revision 005 Section 6: Troubleshooting SBE 63
Section 6: Troubleshooting
This section reviews common problems in operating the SBE 63, and provides
the most likely causes and solutions.
Problem 1: Unable to Communicate with SBE 63
Notes:
• You can use any terminal
program to set up the SBE 63;
set it to 8 data bits, no parity, 1
stop bit, and 9600 baud (default
SBE 63 baud rate). Instructions
here are for using SeatermV2.
See SeatermV2’s Help files.
•
The S> prompt indicates that communications between the SBE 63 and
computer have been established. Before proceeding with troubleshooting,
attempt to establish communications again by clicking Connect in the
Communications menu in Seaterm232.
Cause/Solution 1: The I/O cable connection may be loose. Check the cabling
between the SBE 63 and computer for a loose connection.
Cause/Solution 2: The instrument type and/or its communication settings may
not have been entered correctly in the terminal program. Verify the settings in
the Serial Port Configuration dialog box (Communications menu ->
Configure). The settings should match those on the instrument Configuration
Sheet.
Cause/Solution 3: The I/O cable may not be the correct one.
• The I/O cable supplied with the SBE 63’s optional sensor mount permits
connection to standard 9-pin RS-232 interfaces. See Dimensions and
Connector in Section 2: Description of SBE 63 for the cable pinouts.
Problem 2: Unreasonable Data
The symptom of this problem is data that contains unreasonable values (for
example, values that are outside the expected range of the data).
Cause/Solution 1: Data with unreasonable values may be caused by incorrect
calibration coefficients in the SBE 63 (if looking at data output in converted
format). Verify the calibration coefficients in the SBE 63, using GetCC.
Cause/Solution 2 (MicroCATs only): A data file with unreasonable values
for dissolved oxygen may be caused by incorrect calibration coefficients in the
MicroCAT (SBE 37-SMP-ODO, 37-IMP-ODO, 37-SIP-ODO). Send GetCC
to verify the oxygen calibration coefficients in the MicroCAT match the
SBE 63 Calibration Certificates. Note that calibration coefficients do not affect
the raw data stored in MicroCAT memory.
• If you have not yet overwritten the memory with new data, you can
correct the coefficients and then upload the data again.
• If you have overwritten the memory with new data, you can manually
correct the coefficients in the .xmlcon configuration file (which is
generated when you upload the data from memory), and then reprocess
the data in SBE Data Processing’s Data Conversion module.
35
Page 36
Manual revision 005 Section 6: Troubleshooting SBE 63
Cause/Solution 3 (SeaCATs only): A data file with nonsense values may be
caused by incorrect instrument configuration of the SeaCAT (SBE 16plus V2,
16plus-IM V2, or 19plus V2):
• Bad data may be caused by incorrect setup in the CTD. Send GetCD or
DS to the CTD to verify the CTD setup (SBE 63 is enabled for the
RS-232 auxiliary sensor channel).
Note:
Each SeaCAT CTD is shipped with a
configuration file that matches the
configuration of the instrument
(number and type of auxiliary
sensors, etc.) and includes the
instrument calibration coefficients.
• Bad data may be caused by incorrect configuration in the instrument
.xmlcon configuration file, and/or incorrect calibration coefficients in the
instrument configuration file. Verify the settings in the configuration file.
36
Page 37
Manual revision 005 Glossary SBE 63
Note:
Glossary
PCB – Printed Circuit Board.
SBE 63 – High-accuracy Optical Dissolved Oxygen Sensor.
SBE Data Processing – Sea-Bird’s Windows data processing software,
which calculates and plots temperature, conductivity, and optional internally
mounted pressure, data from auxiliary sensors, and derived variables such as
salinity and sound velocity.
Scan – One data sample.
SeaCAT – High-accuracy conductivity, temperature, and pressure recorder.
Firmware versions of the V2 SeaCAT developed in February 2012 and later
are compatible with the SBE 63. The V2 SeaCAT is available in three
versions:
• 16plus V2 with RS-232 interface
• 16plus-IM V2 with inductive modem interface
• 19plus V2 with RS-232 interface
Seasave V7 – Sea-Bird’s Windows software used to acquire, convert, and
All Sea-Bird software listed was
designed to work with a computer
running Windows XP service pack 2
or later, Windows Vista, or
Windows 7.
display real-time or archived raw data.
Seasoft V2– Sea-Bird’s complete Windows software package, which
includes software for communication, real-time data acquisition, and data
analysis and display. Seasoft V2 includes SeatermV2, Seasave V7, and
SBE Data Processing.
SeatermV2 – Windows terminal program launcher. Depending on the
instrument selected, it launches Seaterm232 (RS-232 instruments),
Seaterm485 (RS-485 instruments), SeatermIM (inductive modem
instruments), or SeatermUSB (USB instruments).
Seaterm232 – Windows terminal program used with Sea-Bird instruments
that communicate via an RS-232 interface, and that were developed or
redesigned in 2006 and later. The common feature of these instruments is the
ability to output data in XML.
Triton X-100 – Reagent grade non-ionic surfactant (detergent), used for
cleaning the conductivity cell. Triton can be ordered from Sea-Bird, but should
also be available locally from chemical supply or laboratory products
companies. Triton is manufactured by Avantor Performance Materials
(www.avantormaterials.com/commerce/product.aspx?id=2147509608).
37
Page 38
Note:
Note:
Manual revision 005 Appendix I: Functional Description SBE 63
Appendix I: Functional Description
The SBE 63’s luminescence decay time decreases non-linearly with increasing
Sea-Bird software performs these
calculations automatically. This
information is included for users who
are developing their own software.
Calibration sheets generated after
July 2012 include information on the
conversion between phase delay in
µsec and volts. Although this
information was not shown on earlier
calibration sheets, the same
conversion is applicable:
• Divide the phase delay output (µsec)
by 39.457071 to get output in volts,
and use the output in volts in the
calibration equation.
oxygen concentration. Because the phase delay between excited and emitted
signals is shifted as a function of the ambient oxygen concentration, the phase
delay is detected instead of the decay time. The signal is characterized by a
modified Stern-Volmer equation as follows:
(ml/L) = [(a0 + a1T + a2V2) / (b0 + b1V) – 1] / Ksv] [S
O
2
Corr
] [P
Corr
]
where
is oxygen concentration (ml/L)
• O
2
• T is temperature output from SBE 63’s thermistor in °C
• V is raw measured phase delay in volts = φ
is raw measured phase delay in µsec (output when SetFormat=1)
• φ
r
• a
0, a1, a2, b0, b1
• K
is Stern-Volmer constant (with calibration coefficients c0, c1, c2)
sv
are calibration coefficients (Uchida et al, 2008)
/ 39.457071 (see Note)
r
(Demas et al, 1999)
• S
• P
is salinity correction function (with calibration coefficients
Corr
, SolB1, SolB2, SolB3, SolC0)
Sol
B0
is pressure correction function (with calibration coefficient E)
Corr
The Stern-Volmer constant equation is:
= c0 + c1T + c2T2
K
sv
where
, c1, c2 are calibration coefficients
• c
0
• T is temperature output from SBE 63’s thermistor in °C
The salinity correction equation is:
= exp [S * (SolB0 + SolB1 * Ts + SolB2 * T
S
Corr
2
+ SolB3 * T
s
3
) + SolC0 * S2]
s
where
• Salinity correction coefficients are constants (Benson and Krause, 1984) -
= -6.24523e-3
Sol
B0
= -7.37614e-3
Sol
B1
= -1.03410e-2
Sol
B2
= -8.17083e-3
Sol
B3
= -4.88682e-7
Sol
C0
= ln [(298.15 – T) / (273.15 + T)]
• T
s
where T is temperature output from SBE 63’s thermistor in °C
• S = salinity
o For oxygen in ml/l output directly from SBE 63, SetRefSal= is used
as the salinity value in the salinity correction equation.
o When the SBE 63 is integrated with a CTD (SeaCAT, MicroCAT, or
Argo CTD), salinity calculated from the CTD data should be used
to calculate converted oxygen (ml/L, mg/L, etc.).
- SeaCAT CTDs output raw phase delay and temperature from an
integrated SBE 63. Sea-Bird software automatically uses the salinity
from the CTD data if calculating converted oxygen output in Seasave
real-time data acquisition software or SBE Data Processing postprocessing software.
- MicroCAT CTDs can output raw phase delay and temperature or
converted oxygen in ml/L from an integrated SBE 63, depending on
the user-selected output format in the MicroCAT. For converted
oxygen in ml/L, the MicroCAT firmware automatically uses the
salinity from the CTD data. Sea-Bird software automatically uses the
salinity from the CTD data if calculating converted oxygen output in
SBE Data Processing post-processing software.
38
Page 39
Manual revision 005 Appendix I: Functional Description SBE 63
The pressure correction equation is:
Pcorr = exp (E * P / K)
where
• Pressure correction coefficient is constant E = 0.011
• K = temperature in Kelvin = T + 273.15
where T is temperature output from SBE 63’s thermistor in °C
• P = pressure (dbar) from CTD data
o For oxygen in ml/l output directly from the SBE 63, SetRefP= is
used as the pressure value in the pressure correction equation.
o When the SBE 63 is integrated with a CTD (SeaCAT, MicroCAT, or
Argo CTD), pressure calculated from the CTD data should be used
to calculate converted oxygen (ml/L, mg/L, etc.).
- SeaCAT CTDs output raw phase delay and temperature from an
integrated SBE 63. Sea-Bird software automatically uses the pressure
from the CTD data if calculating converted oxygen output in Seasave
real-time data acquisition software or SBE Data Processing postprocessing software.
- MicroCAT CTDs can output raw phase delay and temperature or
converted oxygen in ml/L from an integrated SBE 63, depending on
the user-selected output format in the MicroCAT. For converted
oxygen in ml/L, the MicroCAT firmware automatically uses the
pressure from the CTD data. Sea-Bird software automatically uses the
pressure from the CTD data if calculating converted oxygen output in
SBE Data Processing post-processing software.
Sea-Bird provides two calibration sheets with each SBE 63 –
• One relates the SBE 63 oxygen sensor output to oxygen concentration in
ml/L – with coefficients a
0, a1, a2, b0, b1, c0, c1, c2
, and E.
• One relates the SBE 63 thermistor output to temperature (°C) –
with coefficients t
, ta1, ta2, ta3
a0
Examples of both calibration sheets are shown on the next two pages.
39
Page 40

Manual revision 005 Appendix I: Functional Description SBE 63
Example Calibration Sheet – SBE 63 Oxygen Output (Phase Delay µsec)
40
Page 41
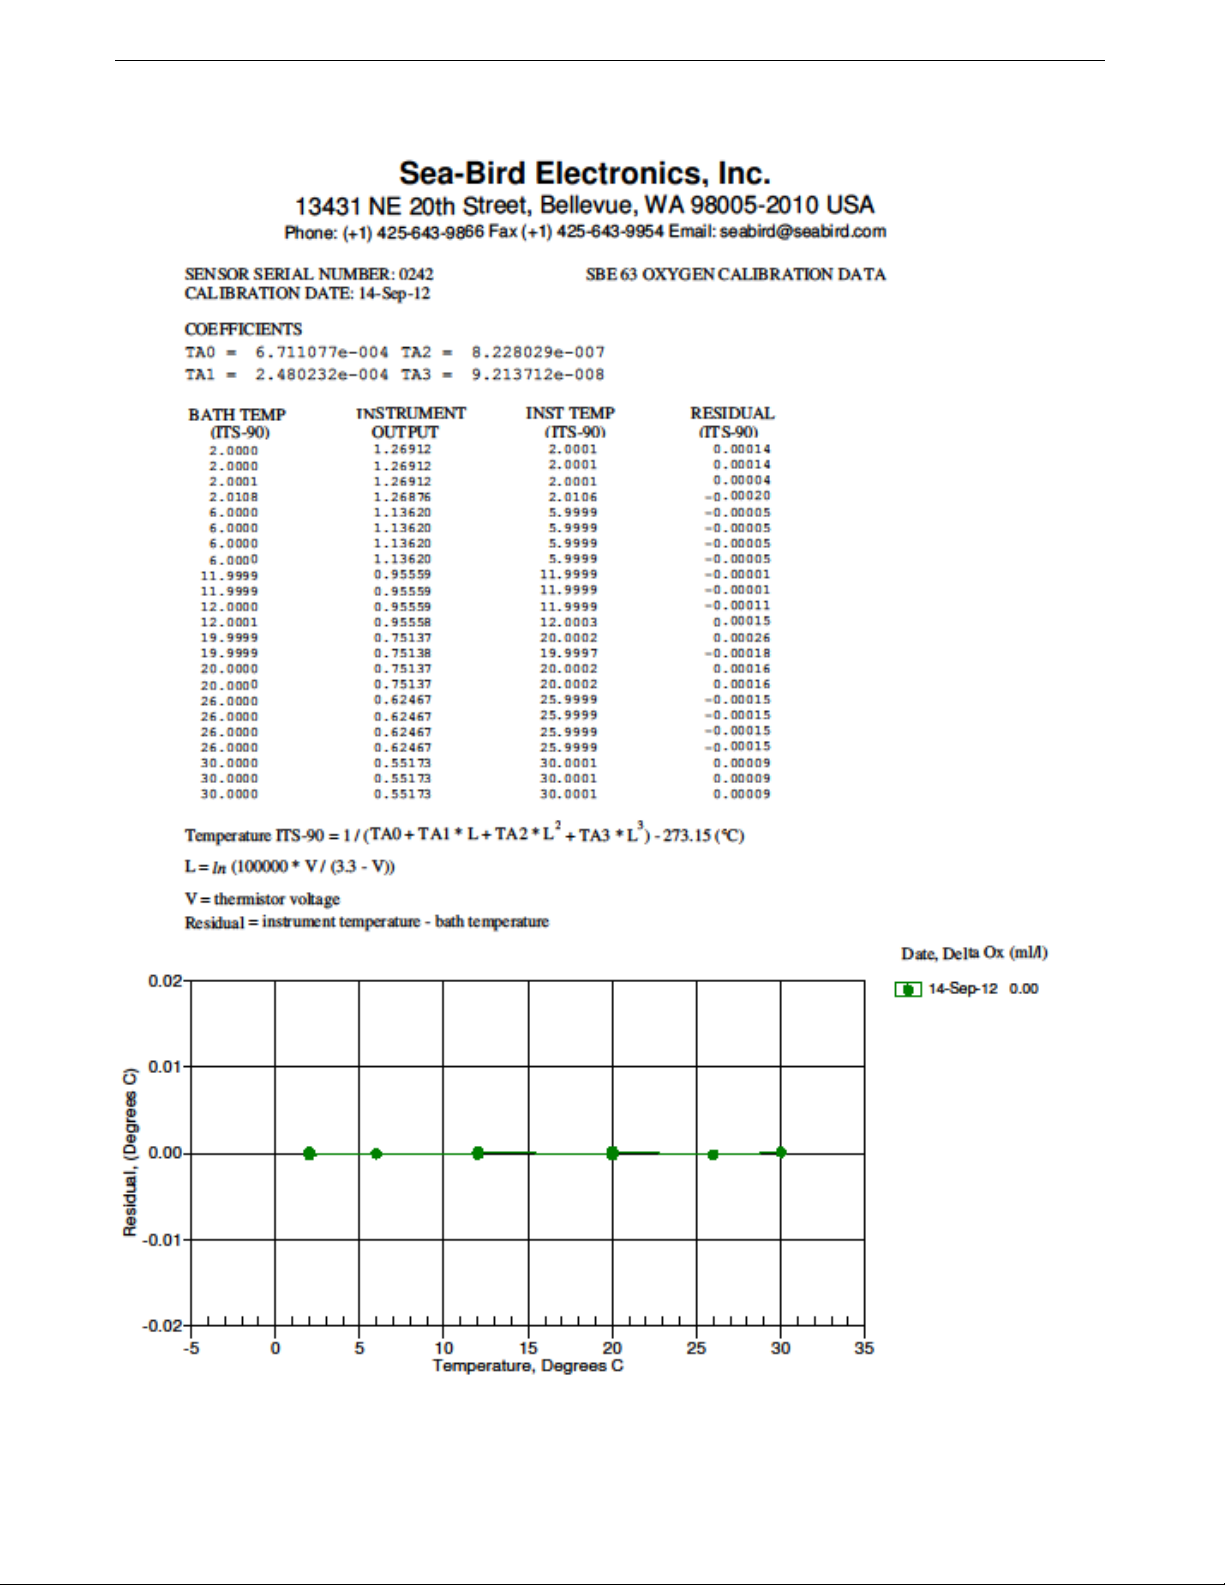
Manual revision 005 Appendix I: Functional Description SBE 63
Example Calibration Sheet – SBE 63 Temperature Output
41
Page 42
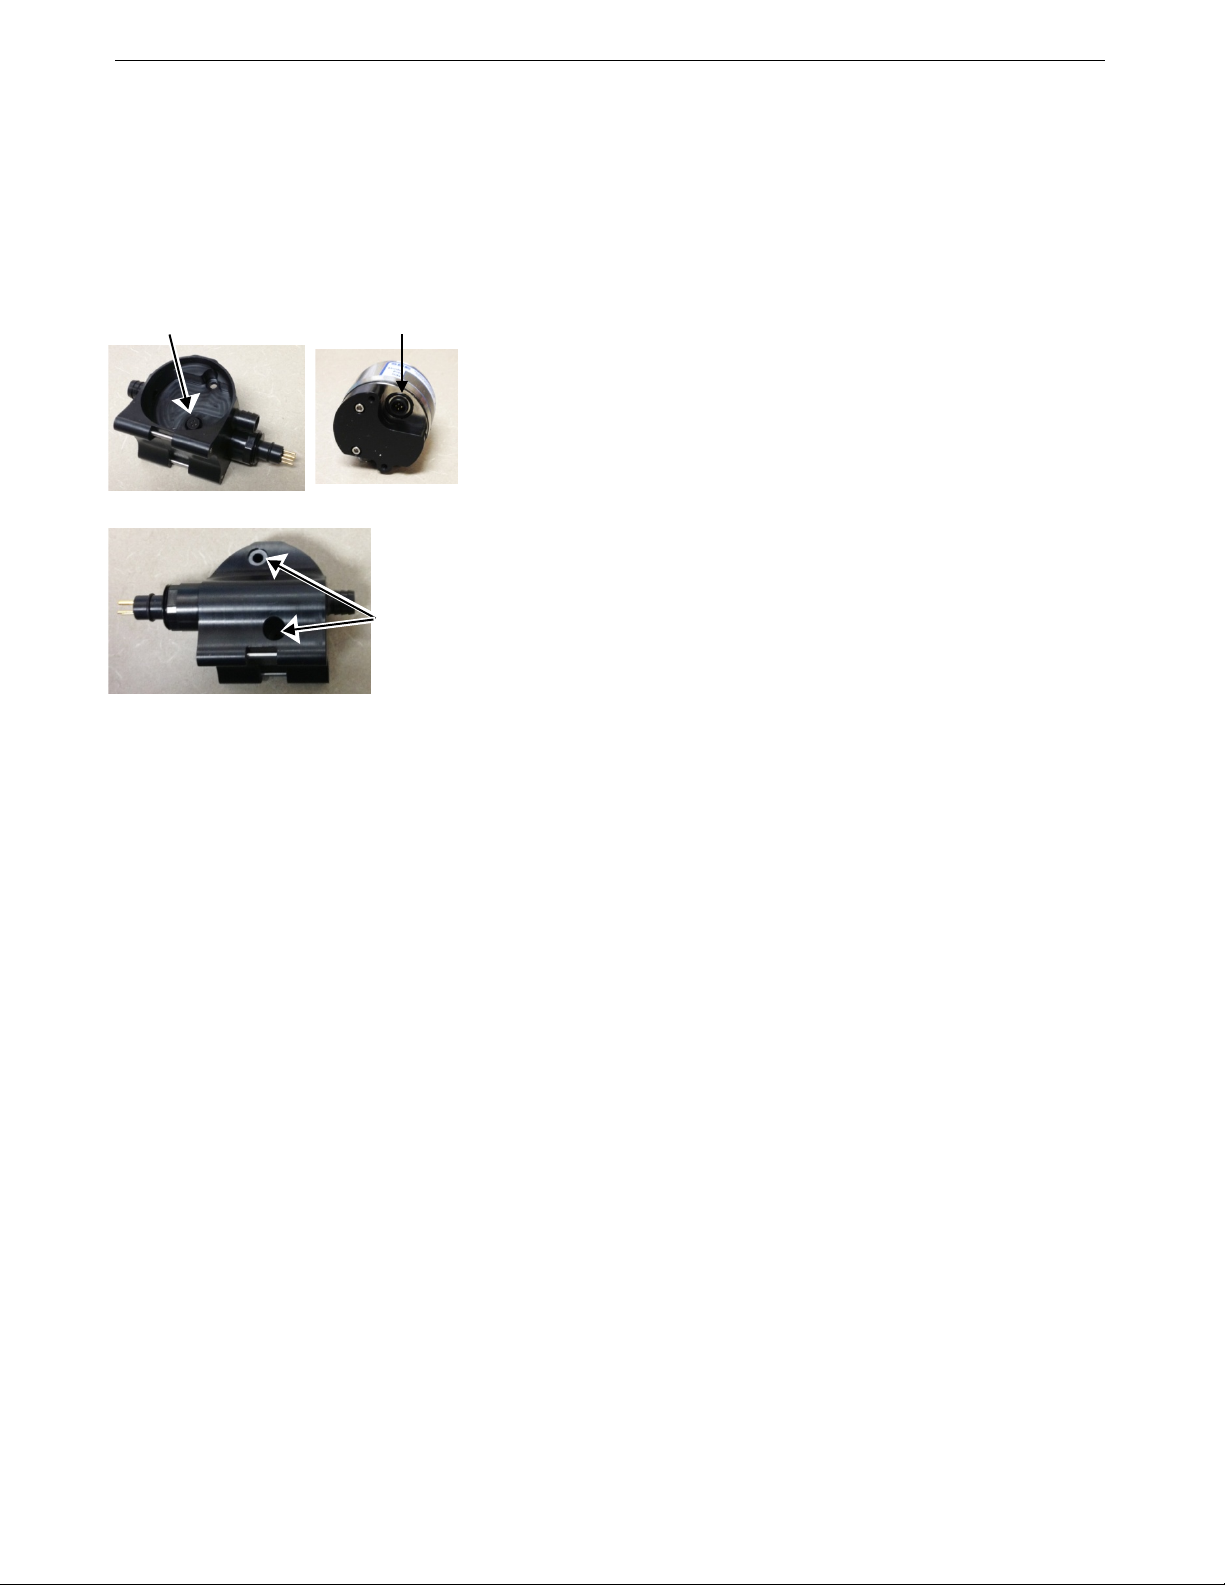
Manual revision 005 Appendix II: Installation/Removal from Optional Sensor Mount SBE 63
SBE 63 – 4-pin
Install
Appendix II: Installation/Removal from Optional Sensor Mount
Installation
Sensor mount –
4-pin connector
connector
cap
screws
(2)
1. Align the 4-pin connectors and push the SBE 63 onto the mount.
2. Install the two #10-24, 1/2” titanium cap screws from the back of the
sensor mount to secure the SBE 63 in the mount.
Removal
1. Remove the two #10-24, 1/2” titanium cap screws from the back of the
sensor mount that secure the SBE 63 in the mount.
2. Pull the SBE 63 straight out of the sensor mount. If it is difficult to
remove:
• Use a rubber glove to provide a better grip as you pull. OR
• Insert one of the cap screws in the sensor mount, and thread it just
one or two turns. Push the head of the screw with a driver; this will
push against the housing and free the O-ring seal. Remove the cap
screws, and then pull the SBE 63 straight out of the sensor mount.
42
Page 43
Manual revision 005 Appendix III: Command Summary SBE 63
GetSD
Get and display Configuration Data.
GetHD
Get and display Hardware Data.
GetCC
Get and display Calibration Coefficients.
x= Baud rate (600, 1200, 2400, 4800, 9600, 14400, 19200, 38400, 56000, 57600, 115200).
Default 9600.
x=1: Echo characters received from computer.
x=0: Converted oxygen and temperature (with units).
x=3: Instrument name, serial number, and converted data.
SetBootDelay
x= delay after power is applied before sampling (1 - 255 sec). Default 1.
SetInterval=x
x= interval (sec) between samples (1 – 32,767) for autonomous sampling. Default 4.
x = number of measurements to average per sample (1–64, or 1–32 for 1Hz sampling); each
SetAutoRun=
x
x=0: Wait for command when power is applied. Default.
x=1: Begin sampling when power is applied. First sample is taken after SetBootDelay=.
*Default
Reset most Setup parameters to factory defaults. Note that baud (SetBaud=) is not reset.
Start autonomous sampling at rate set by SetInterval=. To stop autonomous sampling, click
power.
Stop
Stop autonomous sampling.
TS
Take 1 sample, transmit data in format defined by SetFormat=.
TSR
Take 1 sample, transmit data in raw format (for factory diagnostics).
point number;
SetCalDate=S
S= calibration date (days since January 1, 2000).
SetTA0=F
F=
SetTA1=F
F= TA1 coefficient.
SetTA2=F
F= TA2 coefficient.
SetTA3=F
F= TA3 coefficient.
SetA0=F
F=A0 coefficient.
SetA1=F
F=A1 coefficient.
SetA2=F
F=
SetB0=F
F=
SetB1=F
F= B1 coefficient.
SetC0=F
F=C0 coefficient.
SetC1=F
F=C1 coefficient.
SetC2=F
F=C2 coefficient.
SetE=F
F= E coefficient.
SetSolB0=F
F=
SetSolB1=F
F= SolB1 coefficient.
SetSolB2=F
F= SolB2 coefficient.
SetSolB3=F
F= SolB3 coefficient.
SetSolC0=F
F= SolC0 coefficient.
F=Reference salinity (psu) to use for oxygen calculation in converted units. Default 0. For moorings,
F=Reference pressure (dbar) to use for oxygen calculation in converted units. Default 0. For moorings,
post-processing.
Appendix III: Command Summary
Category Command Description
Status
SetBaud=x
Setup
Sampling
SetEcho=x
SetFormat=x
=x
SetAvg=x
Start or Go
x=0: Do not.
x=1: Raw phase delay and thermistor voltage, converted oxygen and temperature (no units),
for compatibility with SBE 41 (Argo) CTD, SeaCATs (16plus V2, 16plus-IM V2,
19plus V2), and MicroCATs (37-SMP-ODO, 37-IMP-ODO, 37-SIP-ODO). Default.
x=2: Raw and converted data.
Only applicable if AutoRun=1.
measurement takes approximately 0.03 sec. Increasing SetAvg= may shorten sensor film life.
Default 2.
Esc or send Stop (which then allows you to enter status or setup commands), or remove
TA0 coefficient.
Coefficients
(F=floating
S=string with
no spaces)
Initially
factory-set
and should
agree with
Calibration
Certificate
shipped with
SBE 63.
SetRefSal=F
SetRefP=F
A2 coefficient.
B0 coefficient.
SolB0 coefficient.
enter approximate value expected for deployment. For profiling, enter 0, and correct for salinity in postprocessing.
enter approximate value expected for deployment. For profiling, enter 0, and correct for pressure in
43
Page 44
Manual revision 005 Appendix IV: Replacement Parts SBE 63
Secure SBE 63 in optional sensor
mounting on and integration with
mounting on and integration with
Note:
Appendix IV: Replacement Parts
Previous versions of the SBE 63 had a
different hardware configuration, and
required different sensor mounts
(802096 for mount with XSG connector
and 802127 for mount with MCBH
connector, in place of 802273 and
802274). If ordering a mount for an
SBE 63 purchased previously, provide
the SBE 63 serial number so we can
verify the correct sensor mount.
Part
Number
802273
802274
311133
50510
50511
17088
171792
31450
90087 Universal plumbing kit
Sensor mount with
standard (XSG) connector
Sensor mount with
optional wet-pluggable
(MCBH) connector
#10-24 cap screws,
1/2” length, titanium
Sensor mount kit with
standard (XSG) connector
Sensor mount kit with
optional wet-pluggable
(MCBH) connector
Interface cable with
standard (XSG)
connectors
Interface cable with
optional wet-pluggable
(MCBH) connectors
Tygon tubing, 1/2" ID X
3/4" OD, 2 m, Black
Part Application Description
For mounting on and integration
with SBE 16plus V2,
16plus-IM V2, or 19plus V2
For mounting on and integration
with SBE 16plus V2,
16plus-IM V2, or 19plus V2
mount
Kit includes sensor mount
(802273), clamp, and tape; for
SBE 16plus V2, 16plus-IM V2,
or 19plus V2
Kit includes sensor mount
(802274), clamp, and tape; for
SBE 16plus V2, 16plus-IM V2,
or 19plus V2
For integration with SBE 16plus
V2, 16plus-IM V2, or 19plus V2
For integration with SBE 16plus
V2, 16plus-IM V2, or 19plus V2
Main plumbing for integration
with SBE 16plus V2, 16plus-IM
V2, or 19plus V2
Includes air release valve, Yfitting, and tubing for integration
with SBE 16plus V2, 16plus-IM
V2, or 19plus V2
Quantity
in SBE 63
-
-
-
-
-
-
-
-
-
44
Page 45
Manual revision 005 Appendix V: Manual Revision History SBE 63
Manual
Version
001
02/12
• Initial release of production units.
002
05/12
003
06/12
Add information on limitations with high baud rates.
004
01/13
005
04/13
Fix typos.
Appendix V: Manual Revision History
Date Description
• Firmware 1.1: Update status responses to show setting for new command *serpause =
(factory setting).
• Add information on use with SBE 37 MicroCATs (SMP-ODO, IMP-ODO, SIP-ODO).
• Remove information that SBE 19plus V2 must be in moored mode for use with the SBE 63 (it can
be moored or profiling mode).
• Add information on photobleaching to Sensor Calibration in Section 6.
• Add information on Triton-X to glossary.
• Correct typos.
• Correct units in specification -- correct units are µmol/kg, not µM/kg.
• Maximum depth rating 7000 m, not 5000 m.
• Update initial accuracy specification.
• Add example calibration sheets, and information on converting data output to engineering units if
not using Sea-Bird software.
• For Argo float CTD, add information that RS-232 interface required in float controller.
• For integration with RS-485 MicroCAT CTD, add information on required <SerPause> setting.
• Add troubleshooting for incorrect calibration coefficients in MicroCAT integrated with SBE 63.
•
• Firmware 2.0.0: Update GetHD response.
• Clarify that the raw output is the phase delay.
• Update information on software compatibility.
• Correct typos.
• Firmware 3.0.1: Add SetEcho= command, update status responses.
• Update power consumption to 0.08 J/sample from 0.2 J/sample.
• Remove 2000 m option.
• Update drawings, photos, and mount kit part numbers for latest hardware versions (new sensor
connector and sensor mount).
• Update Serial Port Config dialog in Seaterm232.
• Add cables and sensor mount kits for SeaCAT interface to replacement parts.
•
45
Page 46
Manual revision 005 Index SBE 63
Index
Modes · See Sampling modes
A
Averaging · 24
B
Baud · 24
C
Calibration · 7, 34, 38
Calibration coefficient commands · 26
CE certification · 3
Command summary · 43
Commands
calibration coefficients · 26
descriptions · 20
operating · 25
polled sampling · 16
sampling · 25
setup · 24
status · 21
Communication defaults · 13
Connector · 9, 32
Corrosion precautions · 32
D
Data format · 27
Data output format · 24
Declaration of Conformity · 3
Deployment · 29
preparing for · 10
Description · 7
Dimensions · 9
Disassembly/reassembly · 42
E
End cap · 32
F
Format · 24, 27
Functional description · 38
G
Glossary · 37
Mount · 42
O
Operating commands · 25
Output format · 24, 27
P
Parts
replacement · 44
Power · 8
Q
Quick start · 5
R
Recovery · 31
Replacement parts · 44
Revision history · 45
S
Sample interval · 24
Sampling · 7
Sampling commands · 25
Sampling modes · 16
autonomous · 18
polled · 16
Seasoft · 8, 10
Seaterm · 8
Seaterm232 · 11
SeatermV2 · 10, 11
Sensor · 8
Sensor mount · 42
Setup commands · 24
Software · 8
Software installation · 10
Specifications · 8
Status commands · 21
T
Terminal program · 10, 11
Testing · 10
Triton · 37
Troubleshooting · 35
I
Interval · 24
L
Limited liability statement · 2
M
Maintenance · 32, 33
Manual revision history · 45
U
Unpacking SBE 63 · 6
V
Versions · 45
W
Wiring · 10
46
 Loading...