

Page 1
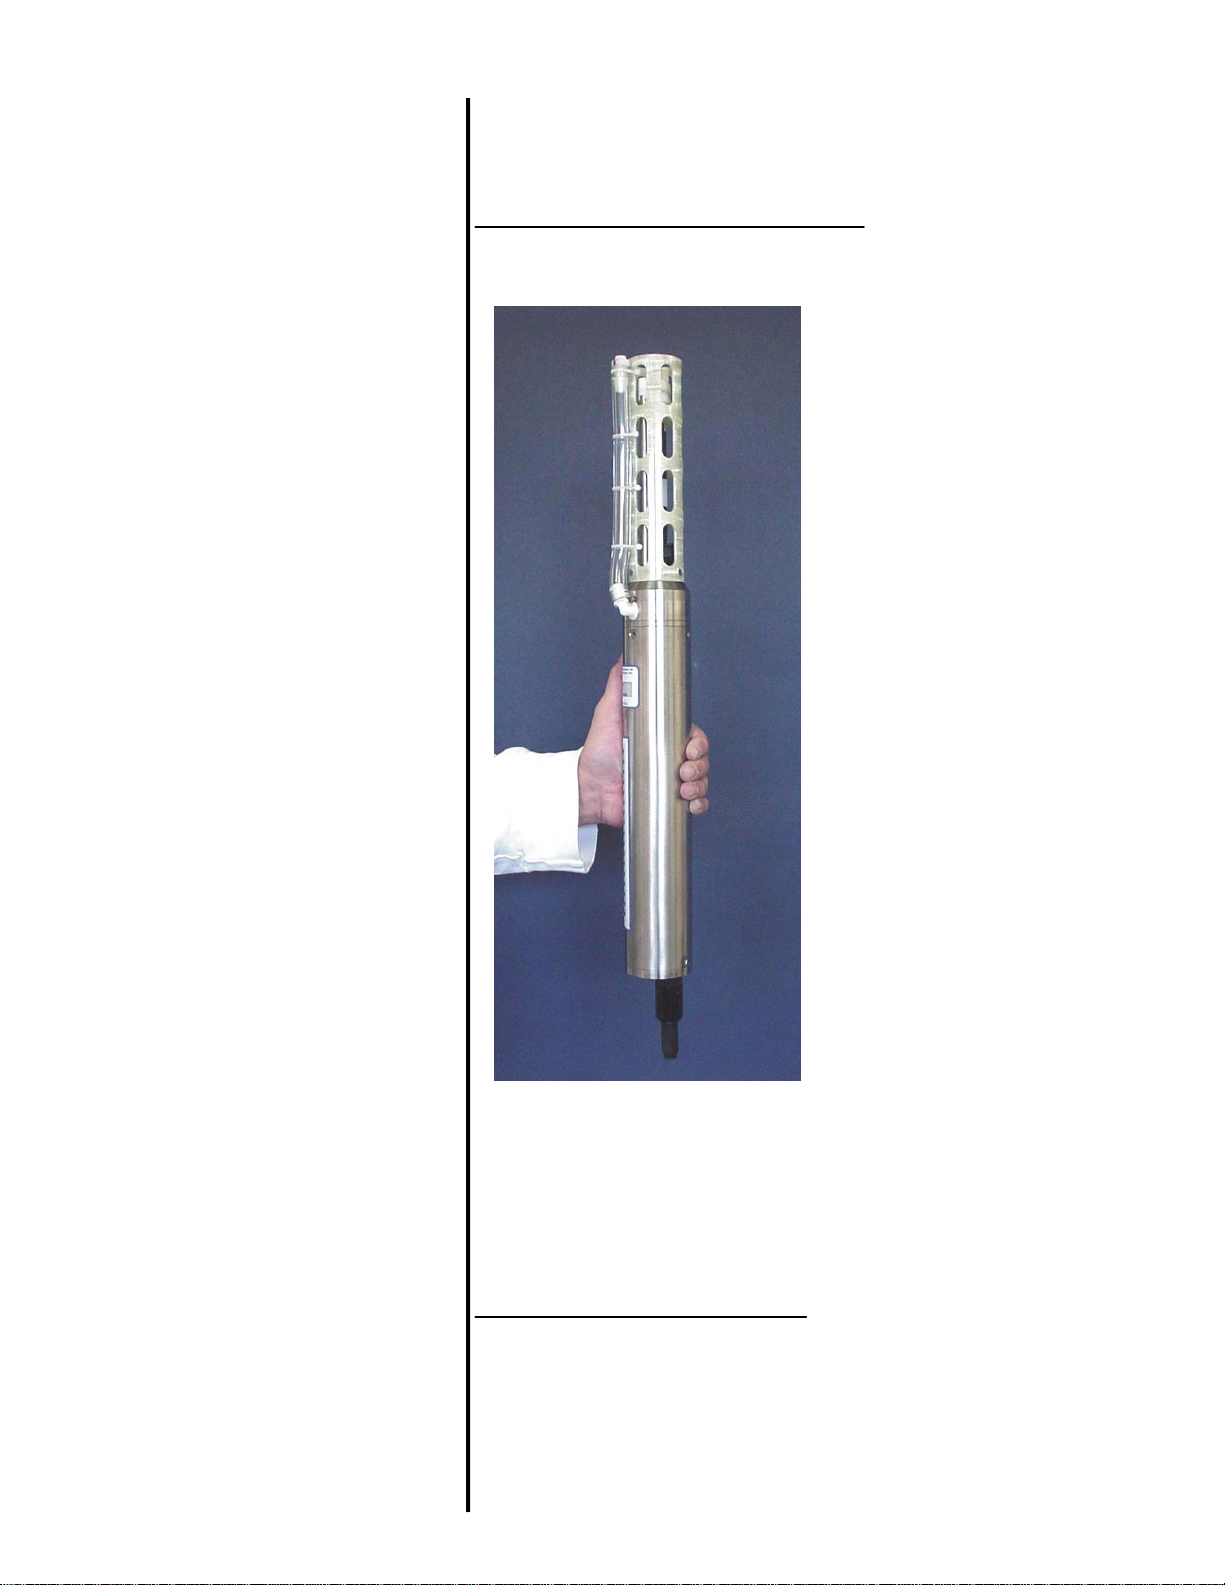
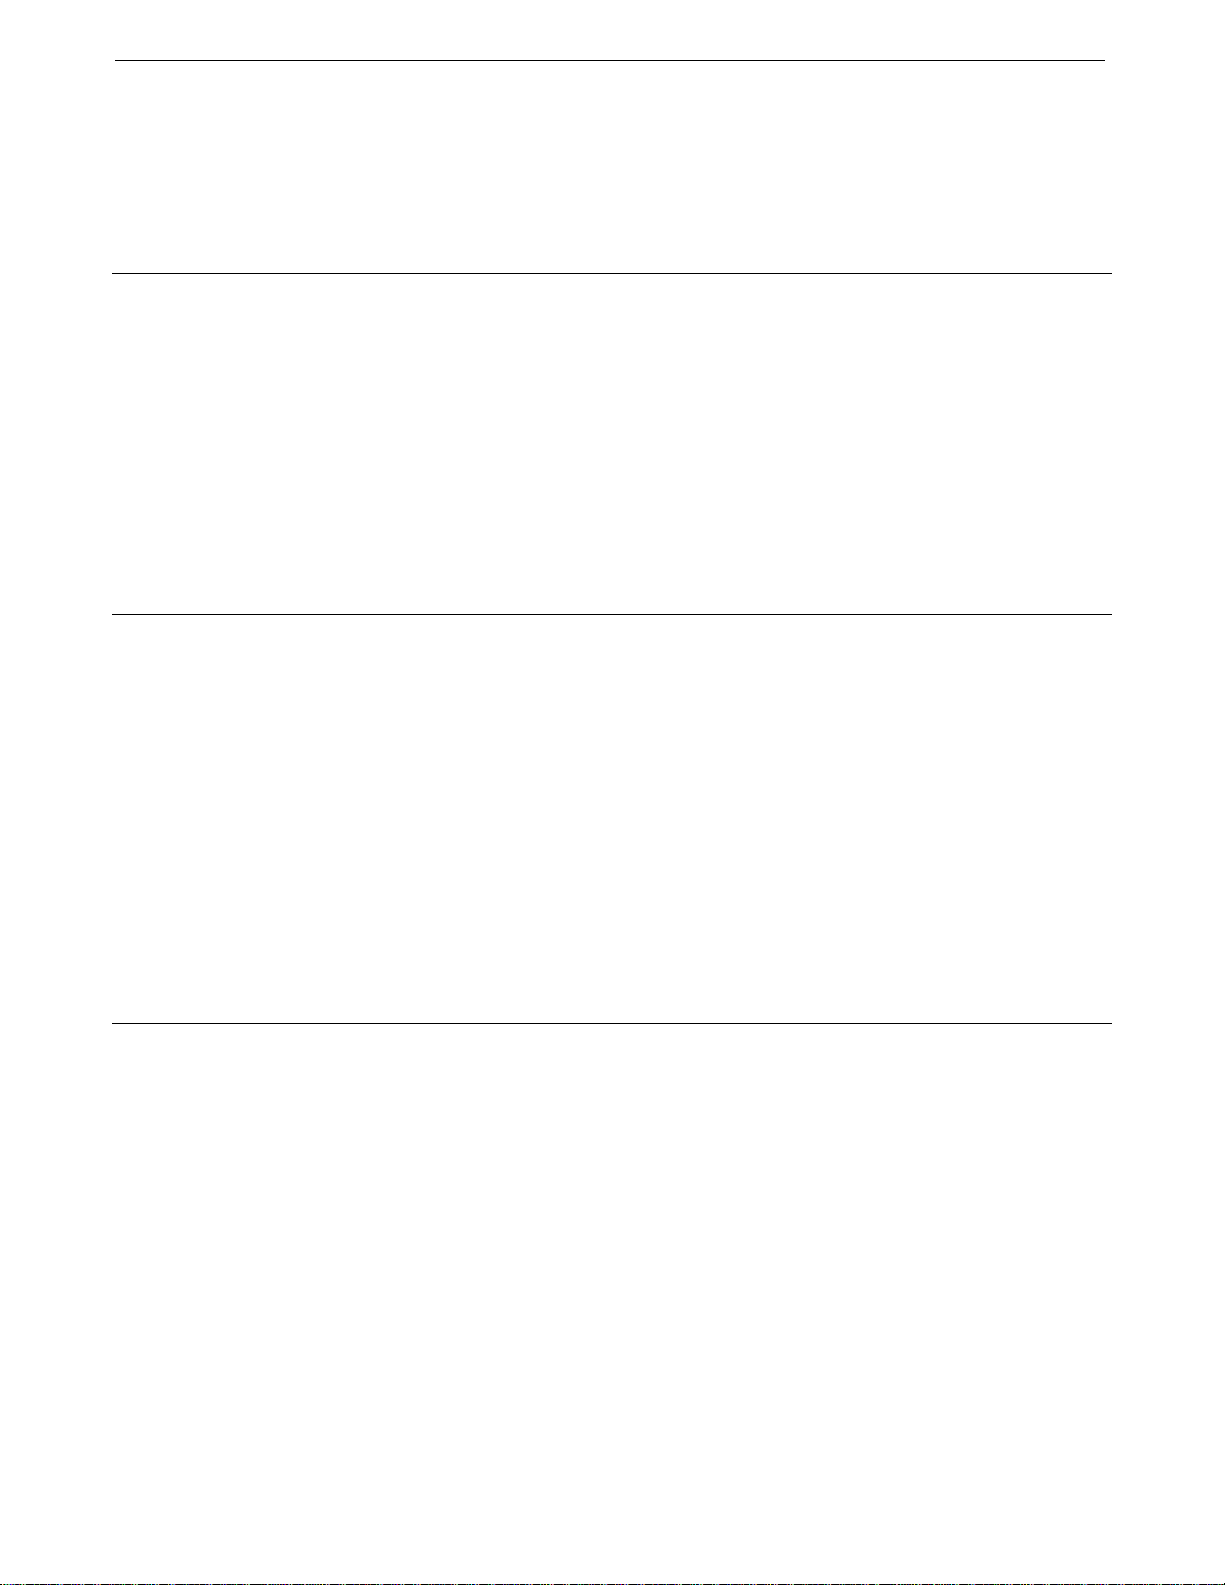
SBE 49 FastCAT
Conductivity, Temperature, and Pressure Sensor
with RS-232 Interface
If deploying vertically, intended for deployment in orientation shown
(sensors at top) for proper pump operation
User’s Manual
Sea-Bird Electronics, Inc.
1808 136
Bellevue, Washington 98005 USA
Telephone: 425/643-9866
Fax: 425/643-9954
E-mail: [email protected] Manual Version #009, 08/04/05
Website: www.seabird.com Firmware Version 1.2 and later
th
Place NE
Page 2
Limited Liability Statement
Extreme care should be exercised when using or servicing this equipment. It should be used or serviced
only by personnel with knowledge of and training in the use and maintenance of oceanographic
electronic equipment.
SEA-BIRD ELECTRONICS, INC. disclaims all product liability risks arising from the use or servicing
of this system. SEA-BIRD ELECTRONICS, INC. has no way of controlling the use of this equipment
or of choosing the personnel to operate it, and therefore cannot take steps to comply with laws
pertaining to product liability, including laws which impose a duty to warn the user of any dangers
involved in operating this equipment. Therefore, acceptance of this system by the customer shall be
conclusively deemed to include a covenant by the customer to defend, indemnify, and hold SEA-BIRD
ELECTRONICS, INC. harmless from all product liability claims arising from the use or servicing of
this system.
2
Page 3
Table of Contents
Table of Contents
Section 1: Introduction........................................................................ 5
About this Manual .............................................................................................5
How to Contact Sea-Bird...................................................................................5
Quick Start.........................................................................................................5
Unpacking FastCAT..........................................................................................6
Section 2: Description of FastCAT..................................................... 7
System Description............................................................................................7
Specifications.....................................................................................................9
Dimensions and End Cap Connector...............................................................10
Data I/O ...........................................................................................................11
Section 3: Power and Communications Test................................... 12
Software Installation........................................................................................12
Test Setup ........................................................................................................12
Test ..................................................................................................................13
Section 4: Deploying and Operating FastCAT................................17
Sampling Modes..............................................................................................17
Polled Sampling........................................................................................18
Autonomous Sampling.............................................................................19
Real-Time Data Corrections............................................................................21
Baud, Cable Length, and Data Transmission Rate...........................................22
Power and Cable Length for FastCAT without Deck Unit..............................23
Command Descriptions....................................................................................24
Data Output Formats........................................................................................31
OUTPUTFORMAT=0 (raw data in Hexadecimal) ..................................31
OUTPUTFORMAT=1 (engineering units in Hexadecimal).....................31
OUTPUTFORMAT=2 (raw data in decimal)...........................................32
OUTPUTFORMAT=3 (engineering units in decimal).............................32
Optimizing Data Quality..................................................................................33
FastCAT Orientation and Pump Use........................................................33
Positioning Relative to Other Instruments................................................34
Profiling Speed .........................................................................................34
Temperature Equilibration........................................................................34
Setup for Deployment......................................................................................35
Deployment......................................................................................................36
Acquiring and Processing Data with SEASAVE and SBE Data Processing...37
Verifying Contents of .con File ................................................................37
Acquiring Real-Time Data with SEASAVE.............................................38
Processing Data with SBE Data Processing .............................................39
Acquiring Real-Time Data with ROV, AUV, etc. for
Processing by Sea-Bird Software.....................................................................40
Recovery..........................................................................................................41
Section 5: Routine Maintenance and Calibration........................... 42
Corrosion Precautions......................................................................................42
Connector Mating and Maintenance................................................................42
Conductivity Cell Maintenance .......................................................................43
Pressure Sensor Maintenance ..........................................................................43
Replacing Optional Anti-Foulant Devices – Mechanical Design Change.......44
Replacing Optional Anti-Foulant Devices (SBE 49).......................................44
Replacing Optional Anti-Foulant Devices (SBE 49).......................................45
Sensor Calibration............................................................................................47
3
Page 4
Table of Contents
Section 6: Troubleshooting................................................................ 49
Problem 1: Unable to Communicate with FastCAT........................................49
Problem 2: Unreasonable Data ........................................................................49
Problem 3: Salinity Lower than Expected.......................................................50
Glossary .............................................................................................. 51
Appendix I: Functional Description and Circuitry......................... 52
Sensors.............................................................................................................52
Sensor Interface...............................................................................................52
Appendix II: Electronics Disassembly/Reassembly........................ 53
Appendix III: Command Summary................................................. 54
Appendix IV: AF24173 Anti-Foulant Device .................................. 56
Appendix V: Real-Time Data Correction Algorithms.................... 60
Aligning Data...................................................................................................60
Filtering Data...................................................................................................62
Applying Conductivity Cell Thermal Mass Correction to Data.......................62
Appendix VI: Replacement Parts..................................................... 63
Index.................................................................................................... 65
4
Page 5
Section 1: Introduction
Section 1: Introduction
This section includes contact information, Quick Start procedure, and photos
of a standard FastCAT shipment.
About this Manual
This manual is to be used with the SBE 49 FastCAT Profiler Conductivity,
Temperature, and Pressure Sensor.
It is organized to guide the user from installation through operation and data
collection. We’ve included detailed specifications, command descriptions,
maintenance and calibration information, and helpful notes throughout
the manual.
Sea-Bird welcomes suggestions for new features and enhancements of our
products and/or documentation. Pl ease e-mail any comments or suggestions to
[email protected].
How to Contact Sea-Bird
Quick Start
Sea-Bird Electronics, Inc.
1808 136
Bellevue, Washington 98005 USA
Business hours:
Monday-Friday, 0800 to 1700 Pacific Standard Time
Except from April to October, when we are on summer time
Follow these steps to get a Quick Start using the FastCAT. The manual
provides step-by-step details for performing each task:
1. Test power and communications (Section 3: Power and
2. Deploy the FastCAT (Section 4: Deploying and Operating FastCAT):
th
Place Northeast
(1600 to 0100 Universal Time)
(1500 to 0000 Universal Time)
Communications Test).
A. Establish setup and sampling parameters.
B. Install I/O cable connector and locking sleeve. Connect other end of
cable to computer/controller and to power supply.
C. Verify hardware and ex ternal fittings are secure.
D. Remove caps from end of T-C Duct and pump exhaust.
E. Apply power.
• If AUTORUN=Y, FastCAT will start sampling automatically.
• If AUTORUN=N, send START to start sampling.
F. Deploy FastCAT.
5
Page 6
Section 1: Introduction
Unpacking FastCAT
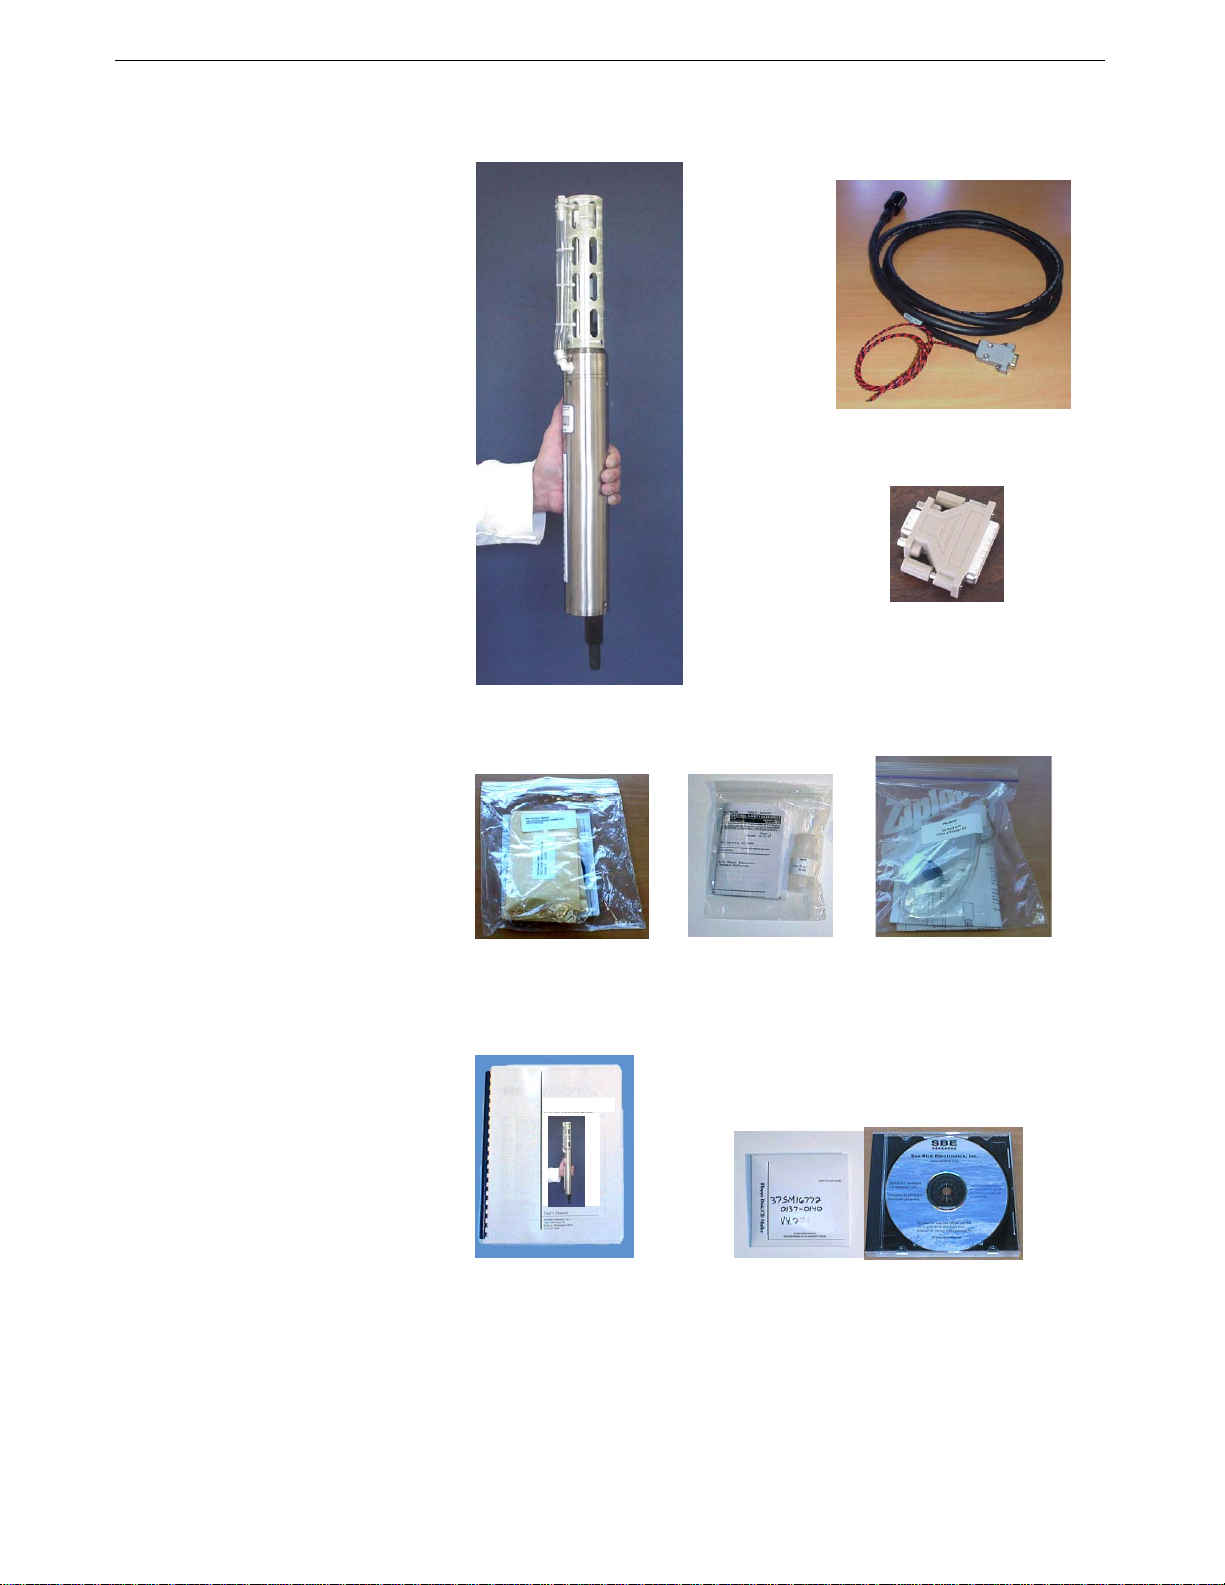
Shown below is a typical FastCAT shipment.
Spare o-ring and
hardware kit (includes
tee exhaust for slow
profiling applications)
SBE 49 FastCAT
FastCAT User Manual
SBE 49
FastCAT
Conductivity cell
cleaning solution
(Triton-X)
Software, and Electronic Copies of
Software Manuals and User Manual
I/O cable
25-pin to 9-pin adapter
(for use with computer
with DB-25 connector)
Conductivity cell filling
and storage kit
6
Page 7
Section 2: Description of FastCAT
p
Section 2: Description of FastCAT
This section describes the functions and features of the SBE 49 FastCAT,
including specifications, dimensions, connector, and communications.
System Description
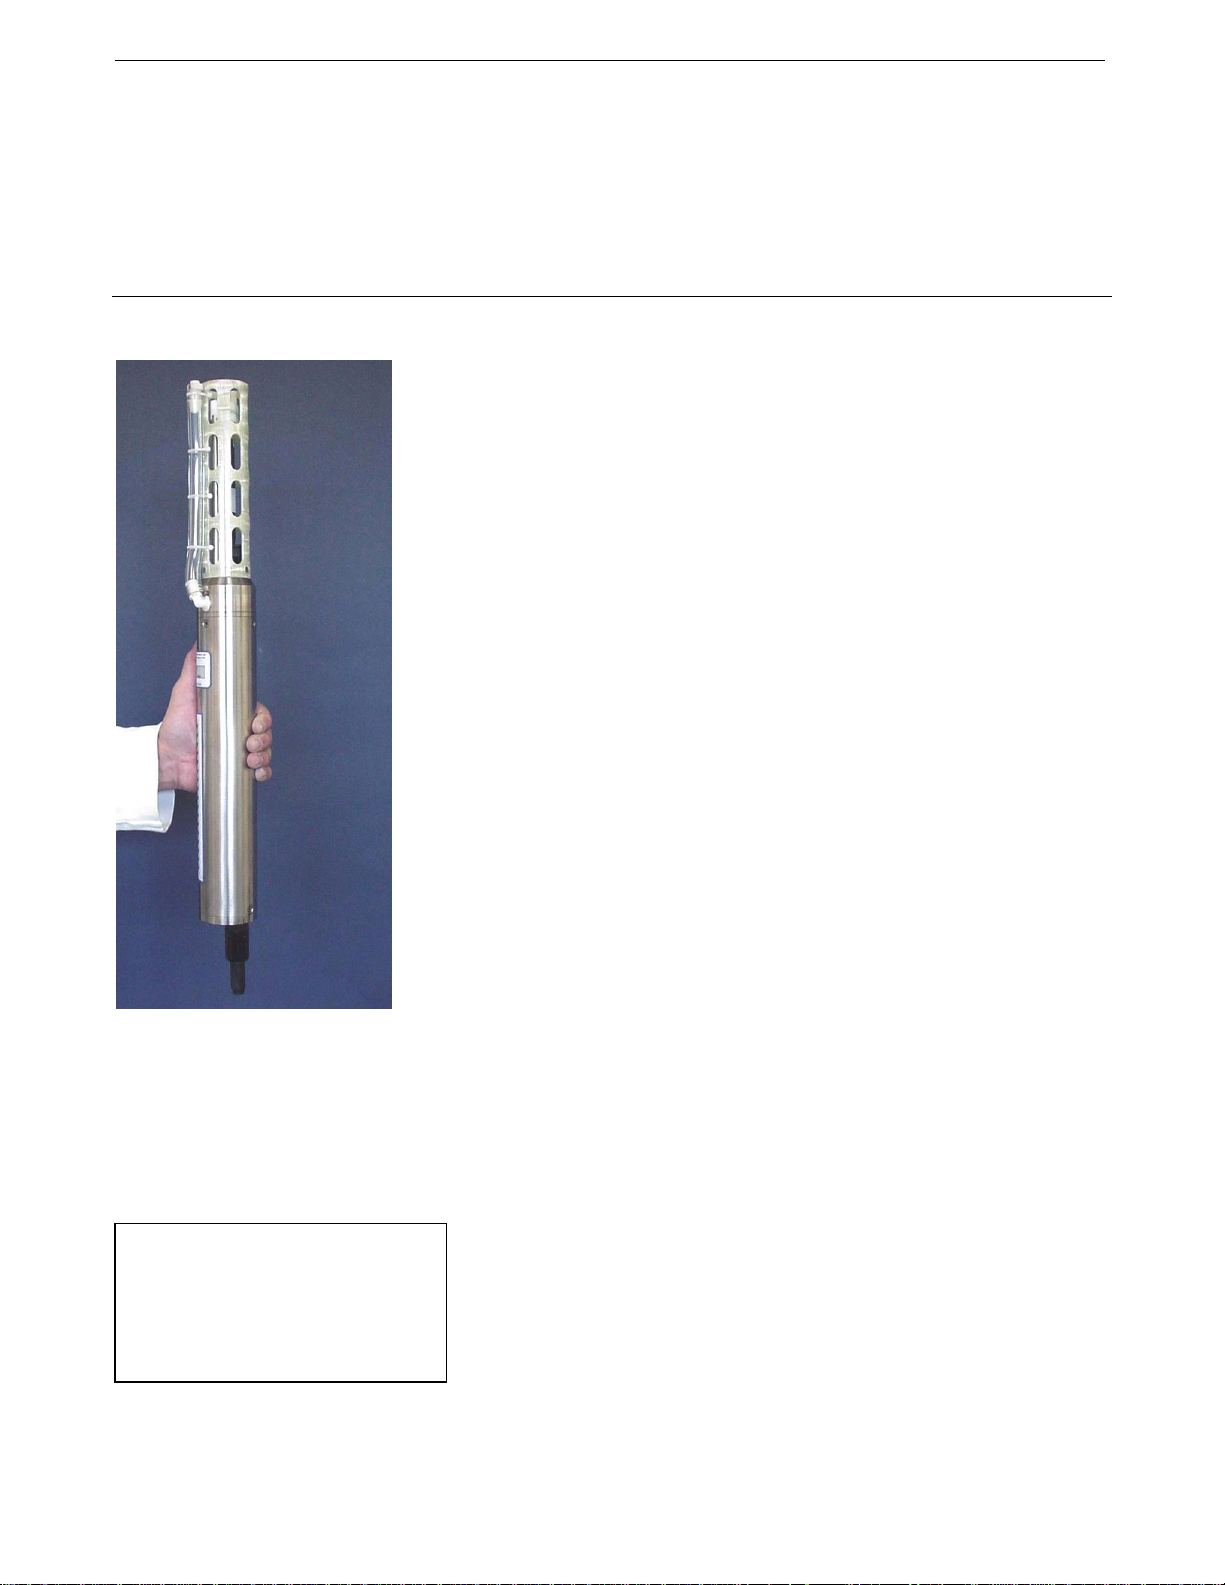
The SBE 49 FastCAT is an integrated CTD sensor intended for towed vehicle,
If deploying
vertically,
intended for
deployment
in orientation
shown
(sensors
at top) for
proper pump
eration
o
Note:
The FastCAT’s pump is not designed
to be used to pump water through
other sensors. Other sensors
requiring pumped water need a
separate pump.
ROV, AUV, or other autonomous profiling applications in marine or freshwater environments at depths up to 7000 meters (22,900 feet). The FastCAT’s
pump-controlled, TC-ducted flow minimizes salinity spiking, and its 16 Hz
sampling provides very high spatial resolutio n of ocean og ra phi c st ructures
and gradients.
The FastCAT’s temperature thermistor and conductivity cell are the same as
used in our premium 911plus CTD system. Its pressure sensor (offered in eight
full scale ranges from 20 to 7000 dbars) is the superior, micro-machined,
silicon strain-gauge recently developed by Druck, Inc. Sophisticated interface
circuitry provides very high resolution and accuracy — entirely comparable to
the 911plus.
The FastCAT is an easy-to-use, light, and compact instrument ruggedly made
of titanium and other low-maintenance (plastic) materials; it is well suited to
even the smallest vehicle. There are straightforward commands for continuous
(full rate or averaged) or single sample acquisition. EEPROM-stored
calibration coefficients permit data output in ASCII engineering units
(degrees C, Siemens/m, decibars, Salinity [PSU], and sound velocity [m/sec]),
or the user can select raw data output if desired.
The FastCAT is externally powered, and its data is telemetered by its RS-232C
interface. The FastCAT has no memory or internal batteries, and does not
support auxiliary sensor inputs.
The FastCAT samples in two modes:
• Autonomous sampling –The FastCAT runs continuously, sampling at
sixteen scans per second (16 Hz). It can be set to average up to
255 samples, transmitting only the averaged data. Programmable real-time
processing – aligning, filtering, and correcting data for conductivity cell
thermal mass effects – provides high quality data for applications where
post-processing is not feasible. The FastCAT can be programmed to begin
autonomous sampling when power is applied or on command.
• Polled sampling – On command, the FastCAT takes one sample and
transmits the data.
A standard FastCAT is supplied with:
• Titanium housing for depths to 7000 meters (22,900 feet)
• Strain-gauge pressure sensor
• Integrated T-C Duct
• Internal pump for flow-control l e d conduct i vity and temperature response
• XSG 4-pin I/O bulkhead connector
• Straight pump exhaust fitting, providing high quality data for
most applications
• Pump exhaust tee fitting, for slow profiling applications – tee fitting is
included in spares kit that ships standard with FastCAT, and can be easily
substituted for the standard straight pump exhaust fitting in the field
7
Page 8
Section 2: Description of FastCAT
FastCAT options include:
• Plastic housing for depths to 350 meters (1150 feet) in lieu of
titanium housing
• MCBH Micro wet-pluggable connector in lieu of XSG connector
• Anti-foulant device fitting and expendable Anti-Foulant Devices for
long deployments
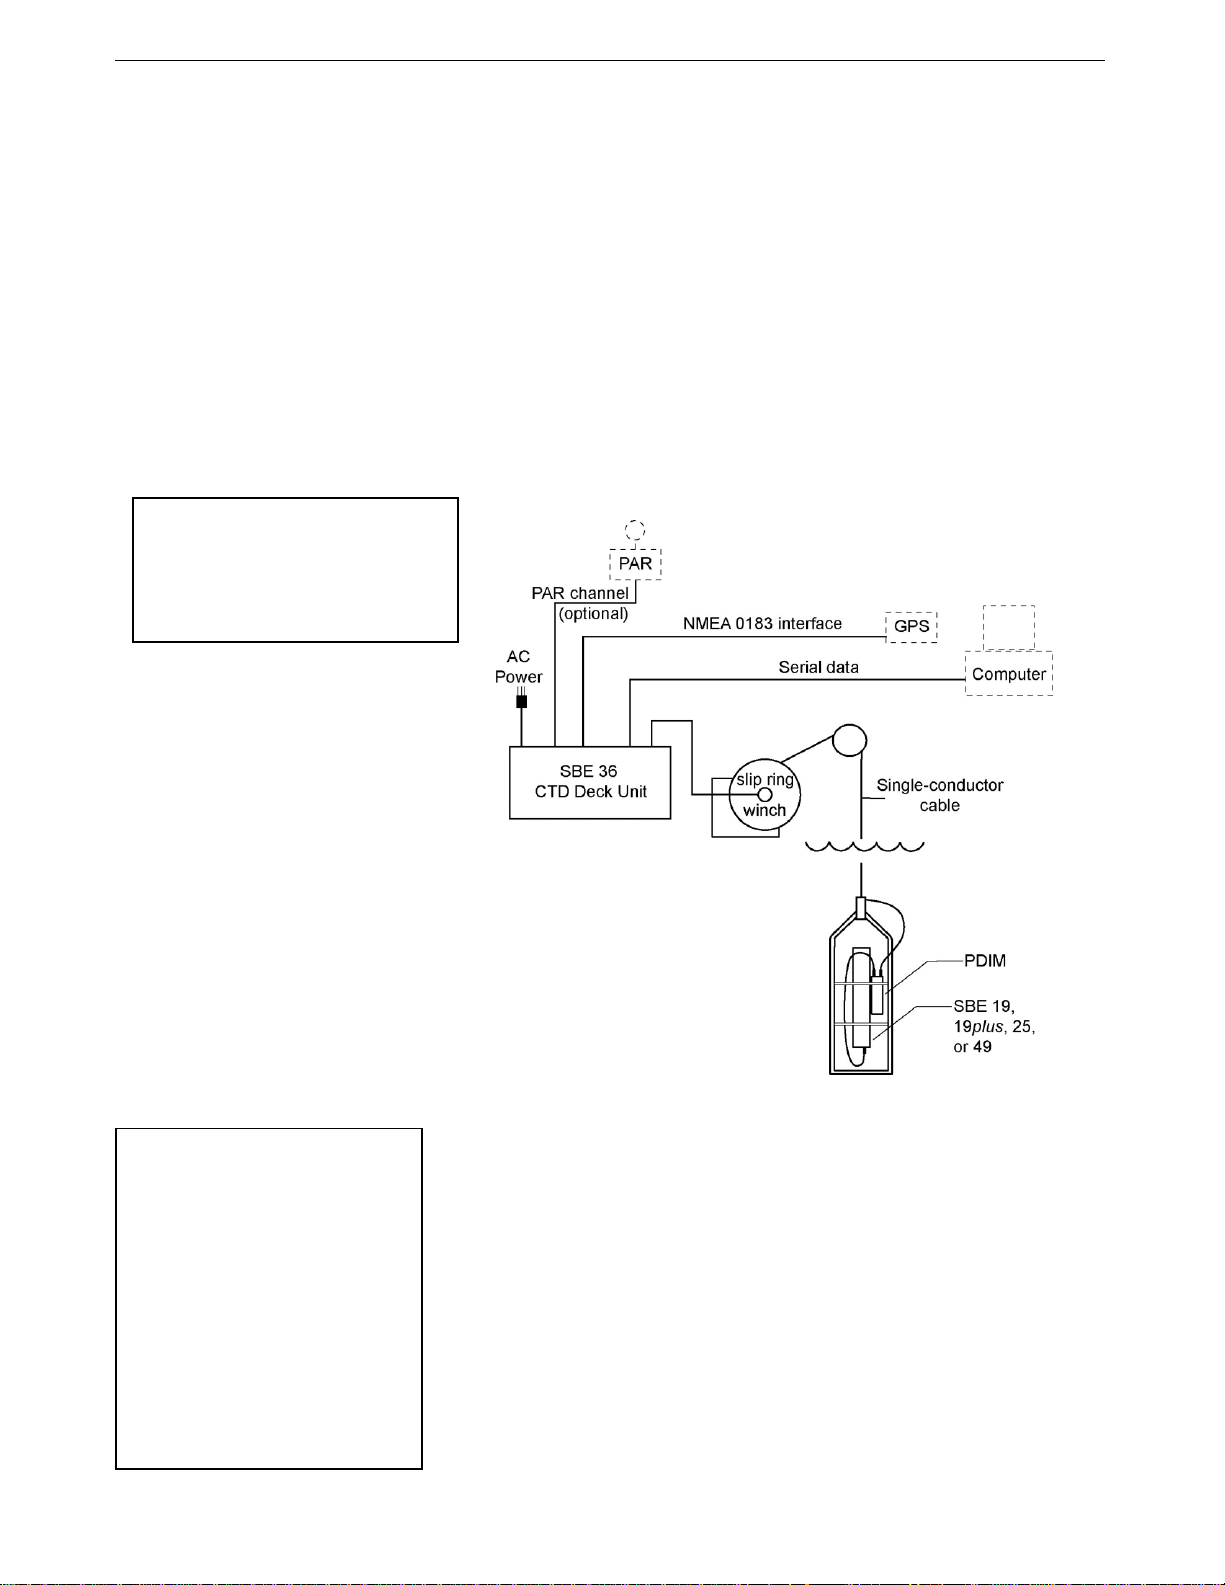
The FastCAT can be used with the SBE 36 CTD Deck Unit and Power Data
Interface Module (PDIM) to provide power and real-time data handling
capability over single-conductor sea cables. The PDIM is a small pressure
housing that is mounted on or near the FastCAT. The PDIM:
• Converts power from the sea cable to + 15 VDC power for the FastCAT.
• Interfaces two-way RS-232 communications from the FastCAT to the
telemetry used on the sea cable. The PDIM converts FastCAT data into
single-wire telemetry for transmission over long (10,000 meter
[32,800 feet]) sea cables.
Note:
When using the FastCAT with the
SBE 36 and PDIM, SEASAVE (our
real-time data acquisition software)
does not allow acquisition of NMEA
or Surface PAR data.
See the SBE 36 / PDIM manual for system operating details.
Notes:
• Help files provide detailed
information on the use of
SEATERM, SEASAVE, and
SBE Data Processing.
• Separate software manuals on
CD-ROM provide detailed
information on the use of
SEASAVE and SBE Data
Processing.
• Sea-Bird also supplies a
DOS software package,
SEASOFT-DOS. However, the
DOS software is not compatible
with the FastCAT.
The FastCAT is supplied with a powerful Win 95/98/NT/2000/XP software
package, SEASOFT-Win32, which includes:
• SEATERM - terminal program for instrument setup and communication.
• SEASAVE - program for real-time acquisition and display of data.
SEASAVE can be used for real-time data acquisition only if the FastCAT
is directly connected to the computer (not connected to an AUV,
ROV, etc.).
• SBE Data Processing - program for calculation and plotting of
conductivity, temperature, pressure, and derived variables such as salinity
and sound velocity.
8
Page 9
Section 2: Description of FastCAT
Specifications
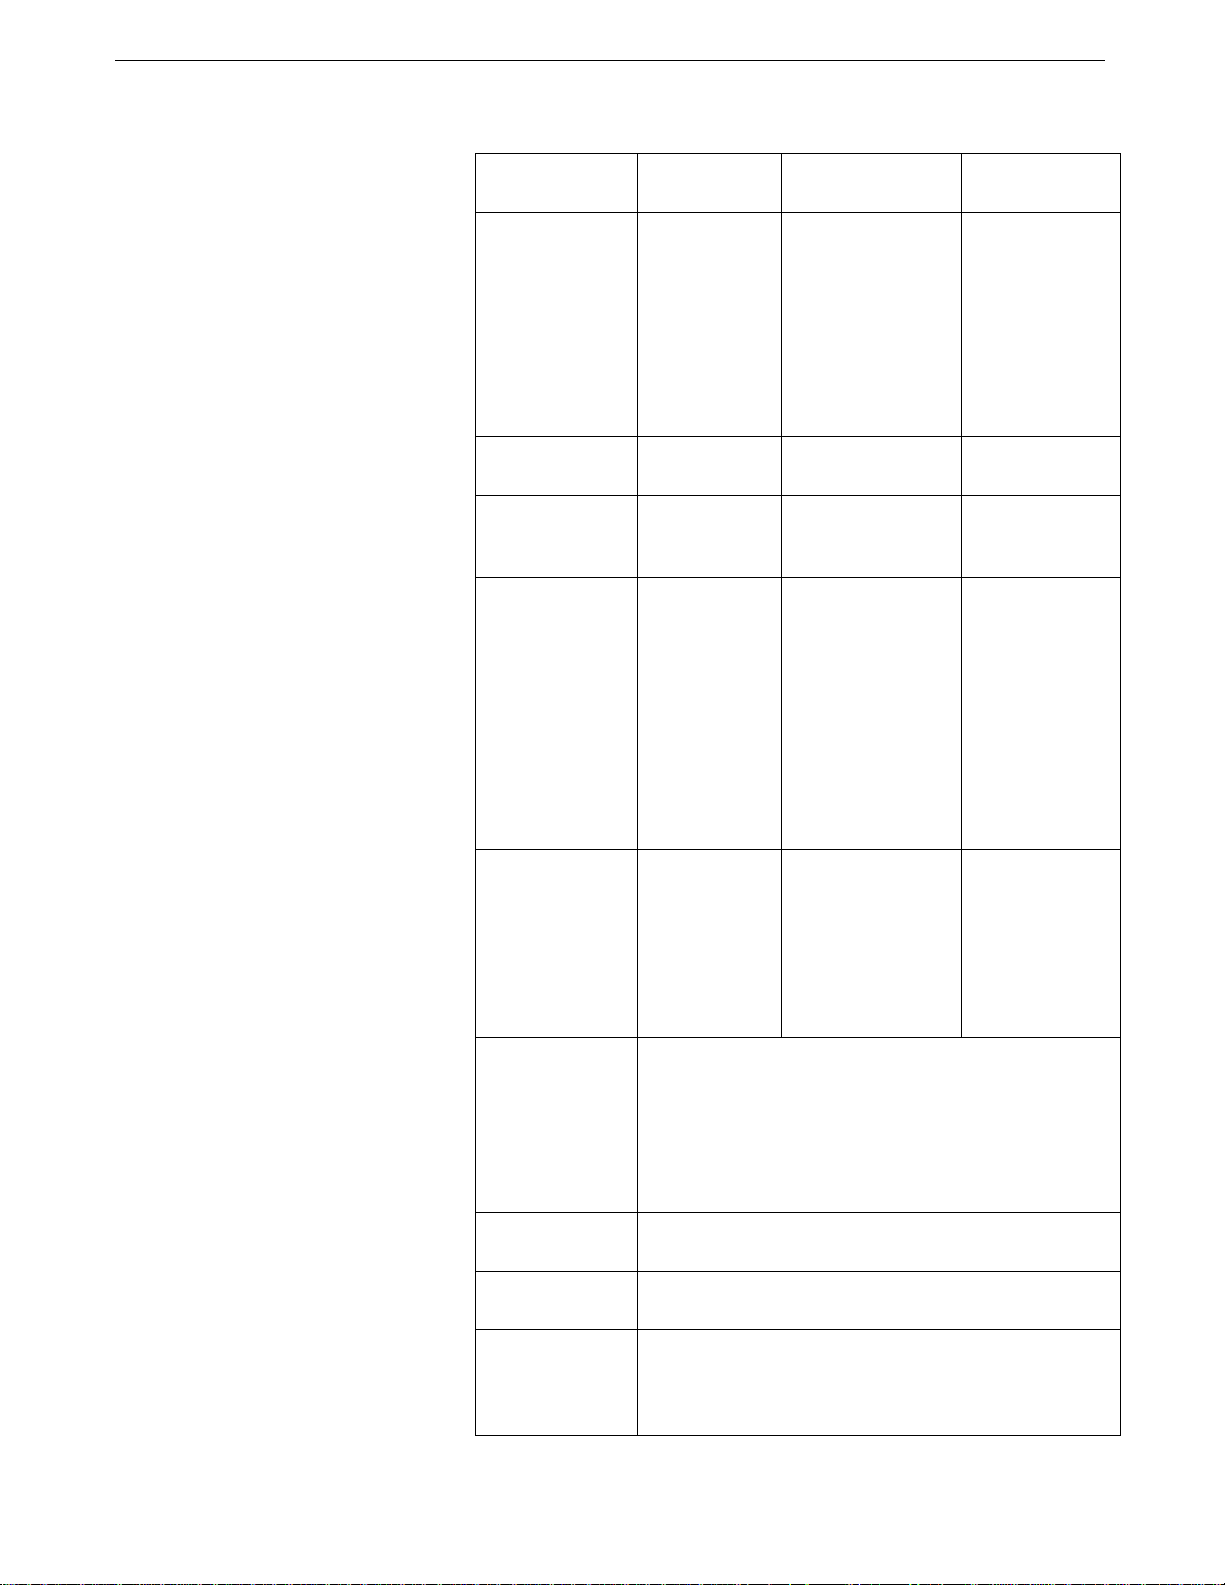
Measurement
Range
Temperature
(°C)
-5 to +35 0 to 9
Conductivity
(S/m)
Pressure
0 to full
scale range:
20 / 100 / 350 /
600 / 1000/
2000 / 3500 /
7000 meters
(expressed in
meters of
deployment depth
capability)
Initial
Accuracy
Typical
Stability
(per month)
Resolution
Sensor
Calibration
(measurement
outside these
ranges may be at
slightly reduced
accuracy due to
extrapolation
errors)
0.002 0.0003
0.0002 0.0003
0.00005
(oceanic waters;
resolves 0.4 ppm
in salinity)
0.00007
0.0001
(high salinity waters;
resolves 0.4 ppm
in salinity)
0.00001
(fresh waters;
resolves 0.1 ppm
in salinity)
0 to 9; physical
calibration over
+1 to +32
the range 2.6 to
6 S/m, plus zero
conductivity (air)
0.1% of
full scale range
0.004% of
full scale range
0.002% of
full scale range
Ambient
pressure to full
scale range in
5 steps
Power
Requirements
Housing
Material
Depth Rating
Weight
9
0.75 Amps at 9-24 VDC
Turn-on transient: 750 mA
Sampling and transmitting data (includes pump):
390 mA at 9 V
285 mA at 12 V
180 mA at 19 V
Standard: 3AL/2.5V Titanium
Optional: Plastic
Standard: 7000 meters (22,900 feet)
Optional: 350 meters (1150 feet)
Standard Titanium Housing -
In air: 2.7 kg (6 lbs) In water: 1.4 kg (3 lbs)
Optional Plastic Housing -
In air: 1.8 kg (4 lbs) In water: 0.5 kg (1 lb)
Page 10
Section 2: Description of FastCAT
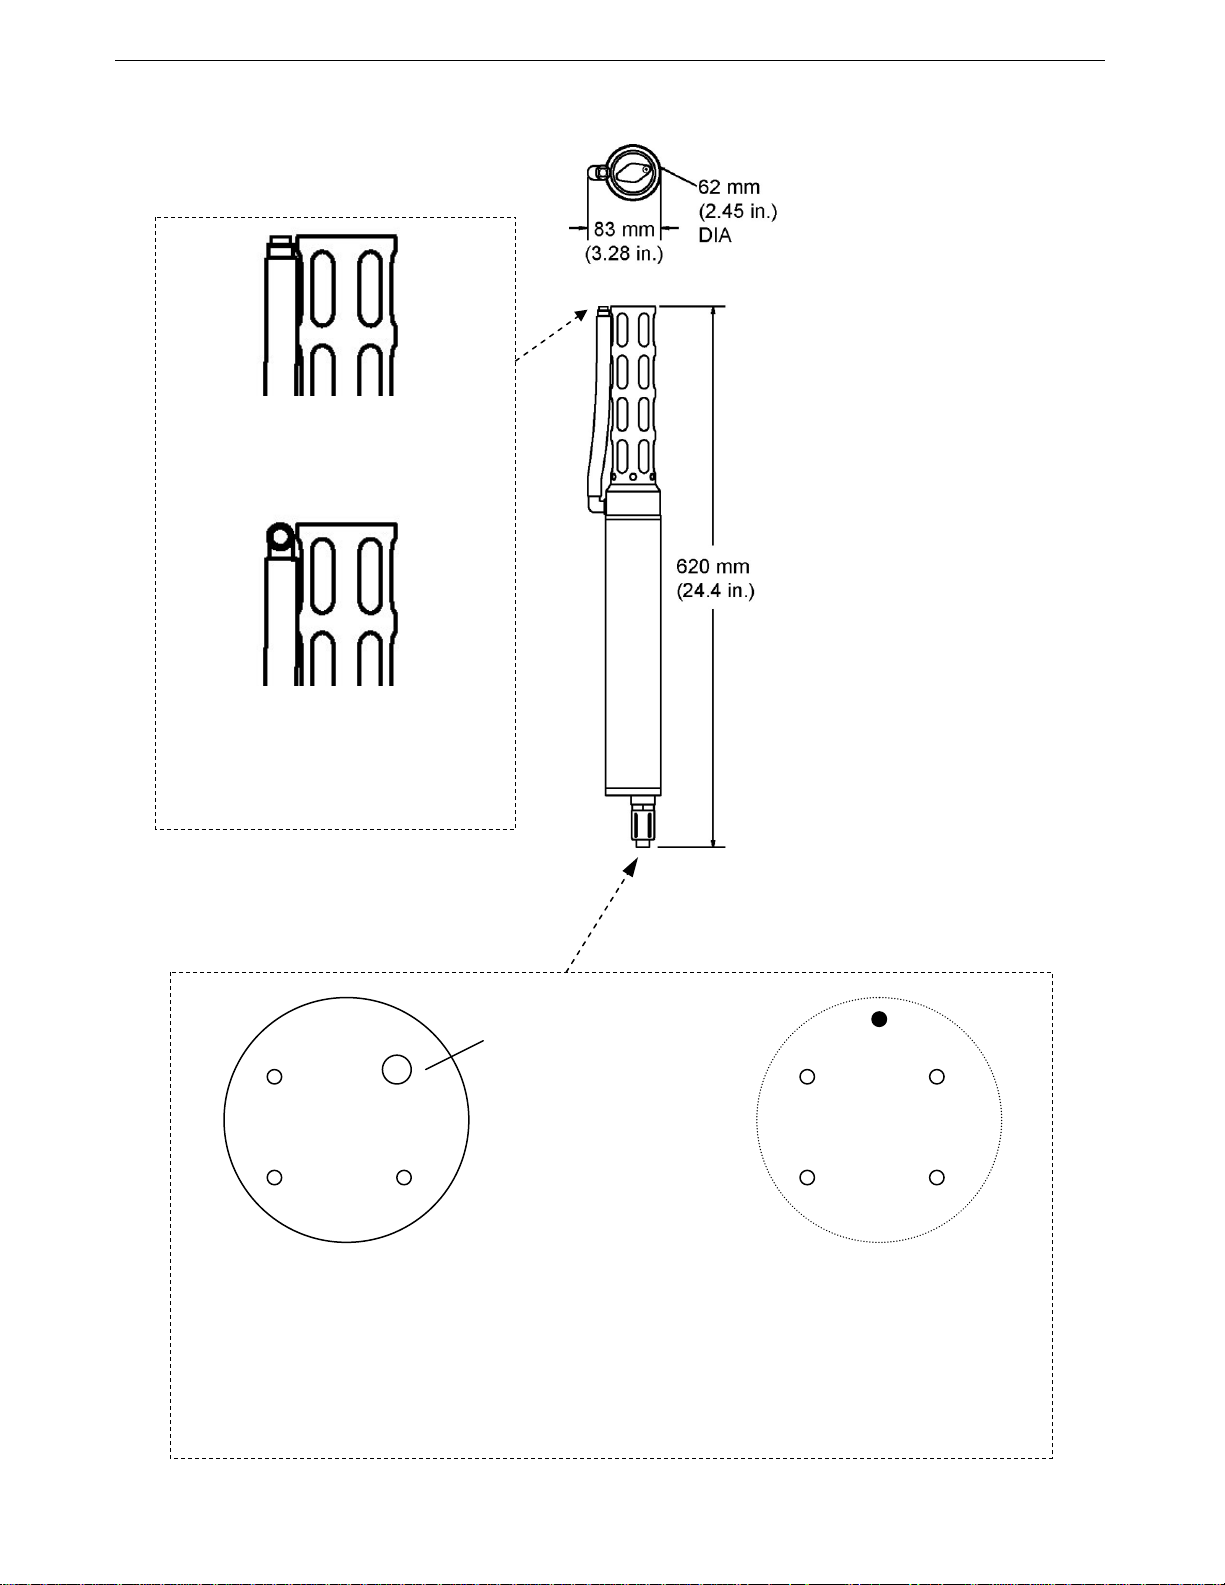
Dimensions and End Cap Connector
FastCAT with straight exhaust
(as shipped by Sea-Bird)
FastCAT with tee exhaust for
slow profiling applications
(tee is in spare parts kit
shipped with FastCAT, and is
easily substituted in the field)
2
3 4
Standard Connector
XSG-4-BCL-HP-SS
1
Align with
raised bump on
connector
Optional MCBH Connector
(3/8” length base, ½-20 thread)
Pin Description
1 Ground
2 RS-232C Receive from computer
3 RS-232C Transmit to computer
4 Power (9-24 VDC)
1 4
3 2
MCBH-4MP (WB), TI
10
Page 11
Section 2: Description of FastCAT
Data I/O
The FastCAT receives setup instructions and outputs data and diagnostic
information via a three-wire RS-232C link, and is factory-configured for
9600 baud, 8 data bits, 1 stop bit, and no parity. FastCAT RS-232 levels are
directly compatible with standard serial interface cards (IBM Asynchronous
Communications Adapter or equal). The communications baud rate can be
changed using the BAUD= command (see Section 4: Deploying and
Operating FastCAT).
11
Page 12
Section 3: Power and Communications Test
Section 3:
Power and Communications Test
This section describes software installation and the pre-check procedure for
preparing the FastCAT for deployment. The power and communications test
will verify that the system works, prior to deployment.
Software Installation
Recommended minimum system requirements for running SEASOFT-Win32:
Pentium 90 CPU, 64 Mbyte RAM, Windows 98 or later.
If not already installed, install SEATERM (terminal program) and other Sea-
Note:
It is possible to use the FastCAT
without SEATERM by sending
direct commands from a dumb
terminal or terminal emulator, such
as Windows HyperTerminal.
Bird software programs on your computer using the supplied software CD:
1. Insert the CD in your CD drive.
2. Double click on Seasoft-Win32.exe.
3. Follow the dialog box directions to install the software.
The default location for the software is c:/Program Files/Sea-Bird. Within that
folder is a sub-directory for each program. The installation program allows
you to install the desired components. Install all the components, or just install
SEATERM for now.
Test Setup
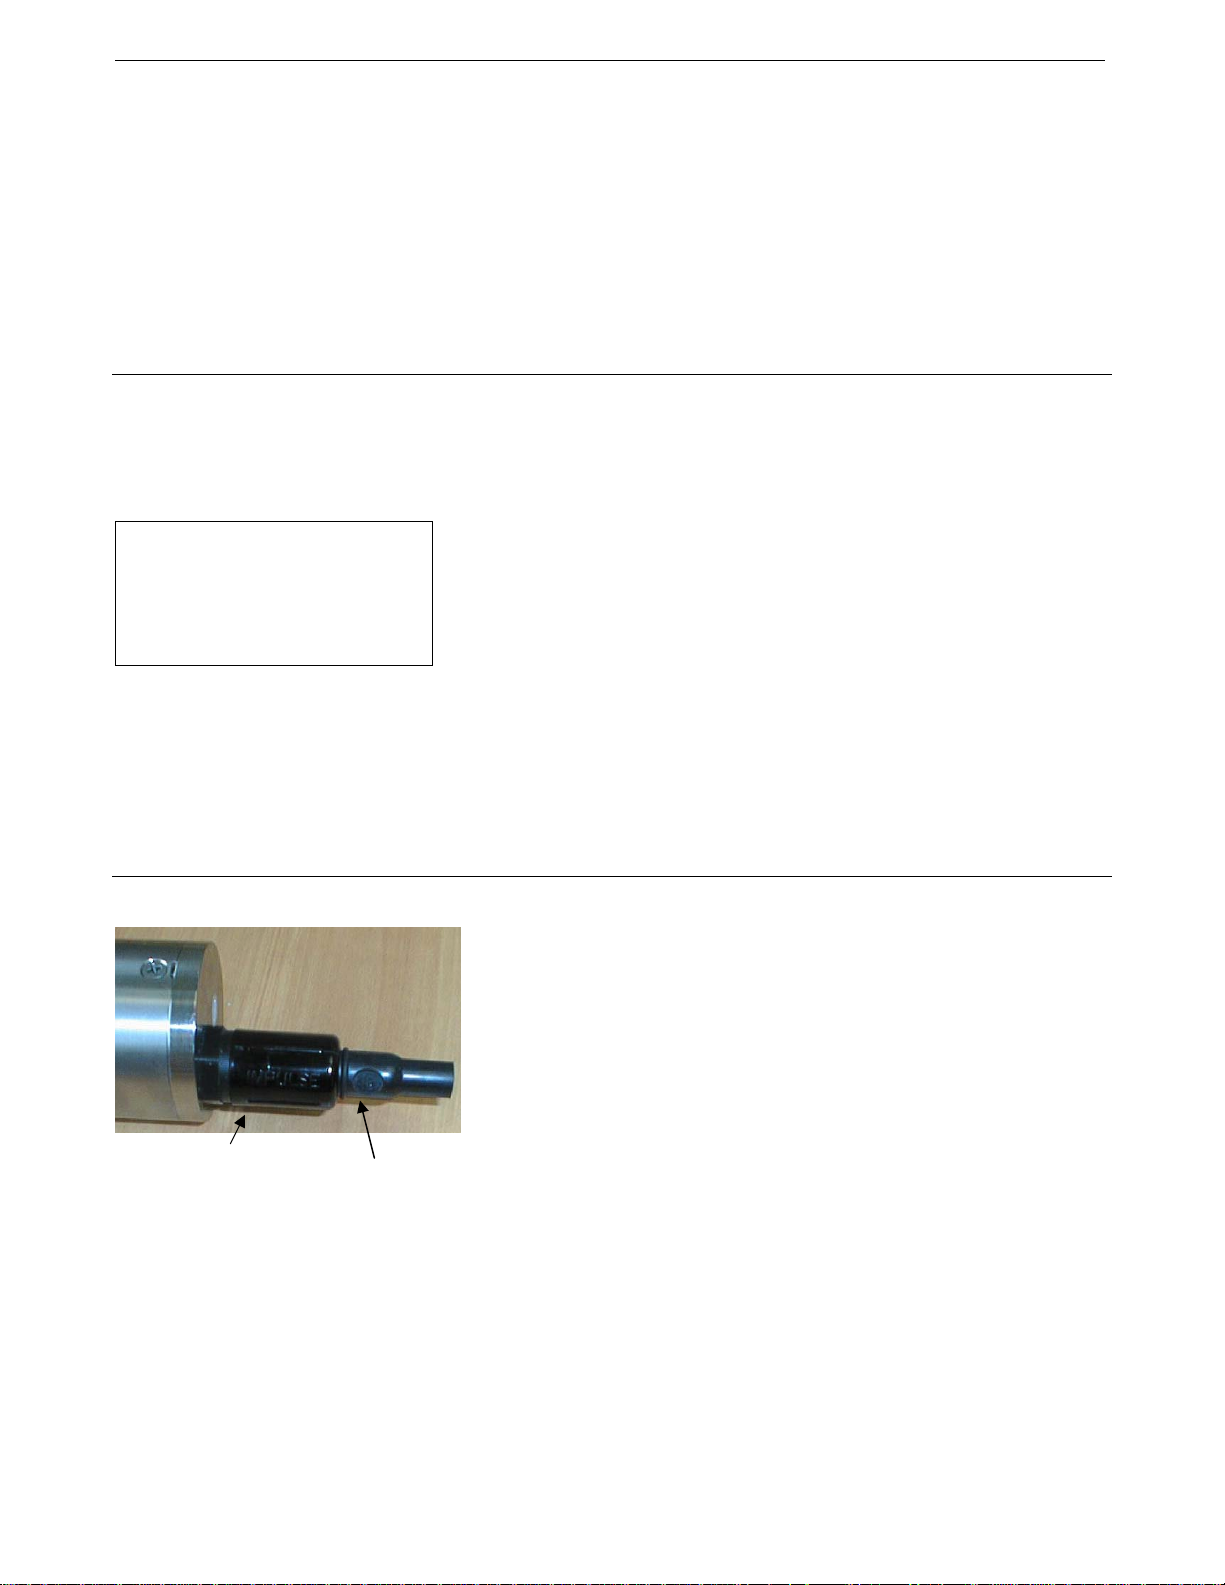
Locking
sleeve
Dummy
plug
1. Remove the dummy plug and install the I/O cable:
A. By hand, unscrew the locking sleeve from the FastCAT’s I/O
connector. If you must use a wrench or pliers, be careful not to loosen
the I/O connector instead of the locking sleeve.
B. Remove the dummy plug from the FastCAT’s I/O connector by
pulling the plug firmly away from the connector.
C. Standard Connector - Install the Sea-Bird I/O cable connector,
aligning the raised bump on the side of the connector with the large
pin (pin 1 - ground) on the FastCAT. OR
MCBH Connector – Install the cable connector, aligning the pins.
2. Connect the I/O cable connector to your computer’s serial port.
3. Connect the I/O cable connector’s red (+) and black (-) wires to a power
supply (9-24 VDC). See Section 2: Description of FastCAT, for the
connector details.
12
Page 13
Section 3: Power and Communications Test
Test
Note:
See SEATERM’s help files for
detailed information on the use
of the program.
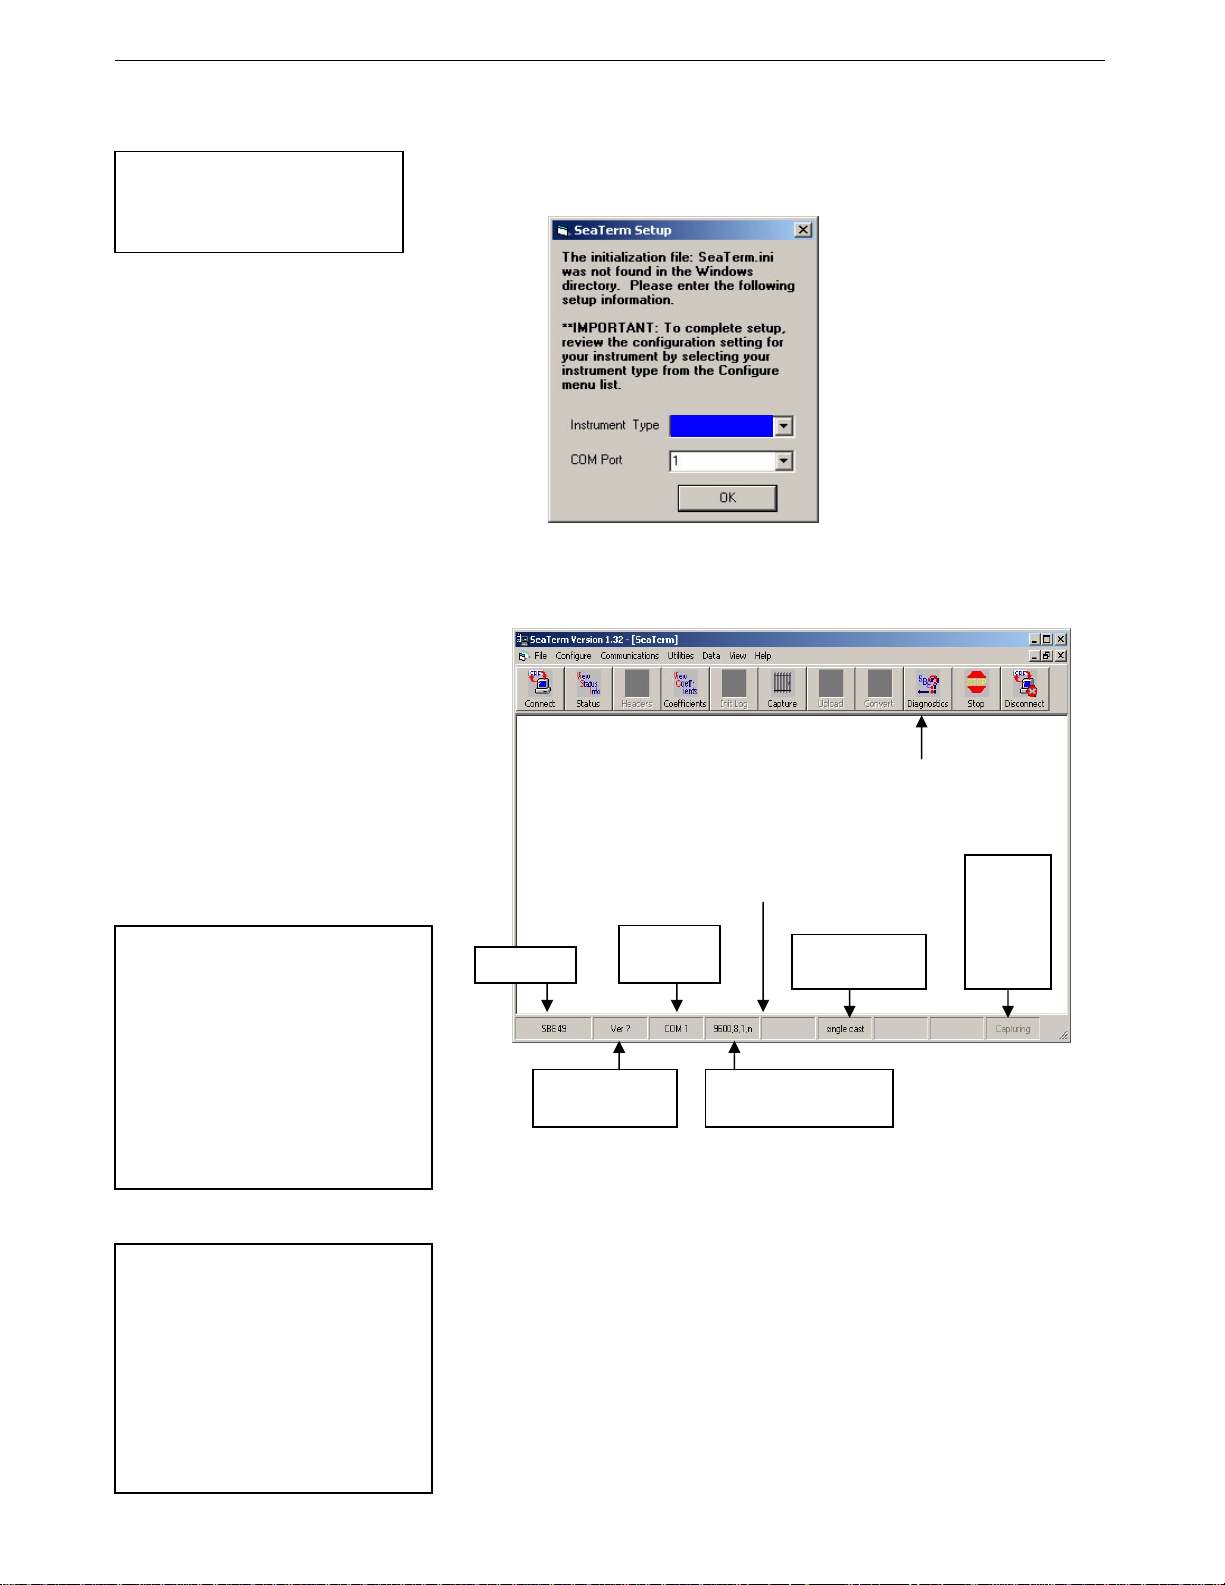
1. Double click on SeaTerm.exe. If this is the first time the program is used,
the setup dialog box may appear:
SBE49
Select the instrument type (SBE 49) and the computer COM port for
communication with the FastCAT. Click OK.
2. The main screen looks like this:
Note:
There is at least one way, and as
many as three ways, to enter
a command:
• Manually type a command in
Command/Data Echo Area
• Use a menu to automatically
generate a command
• Use a Toolbar button to
automatically generate
a command
Note:
Once the system is configured and
connected (Steps 3 through 5
below), to update the Status bar:
• on the Toolbar, click Status; or
• from the Utilities menu, select
Instrument Status.
SEATERM sends the status
command, which displays in the
Command/Data Echo Area, and
updates the Status bar.
Menus
Toolbar
Command/Data Echo Area
Capture
Status bar
Computer
Instrument
Instrument
EPROM version
COM port
Baud rate, data bits,
stop bits, and parity
• Menus – Contains tasks and frequently executed instrument
commands.
• Toolbar – Contains buttons for frequently executed tasks and
instrument commands. All tasks and commands accessed through the
Toolbar are also available in the Menus. To display or hide the
Toolbar, select View Toolbar in the View menu. Grayed out Toolbar
buttons are not applicable.
• Command/Data Echo Area – Echoes a command executed using a
Menu or Toolbar button, as well as the instrument’s response.
Additionally, a command can be manually typed in this area, from the
available commands for the instrument. Note that the instrument must
be awake for it to respond to a command (use Connect on the Toolbar
to wake up the instrument).
• Status bar – Provides status information. To display or hide the Status
bar, select View Status bar in the View menu.
(not applicable
to FastCAT)
to file
status –
grayed
out if not
capturing
13
Page 14
Section 3: Power and Communications Test
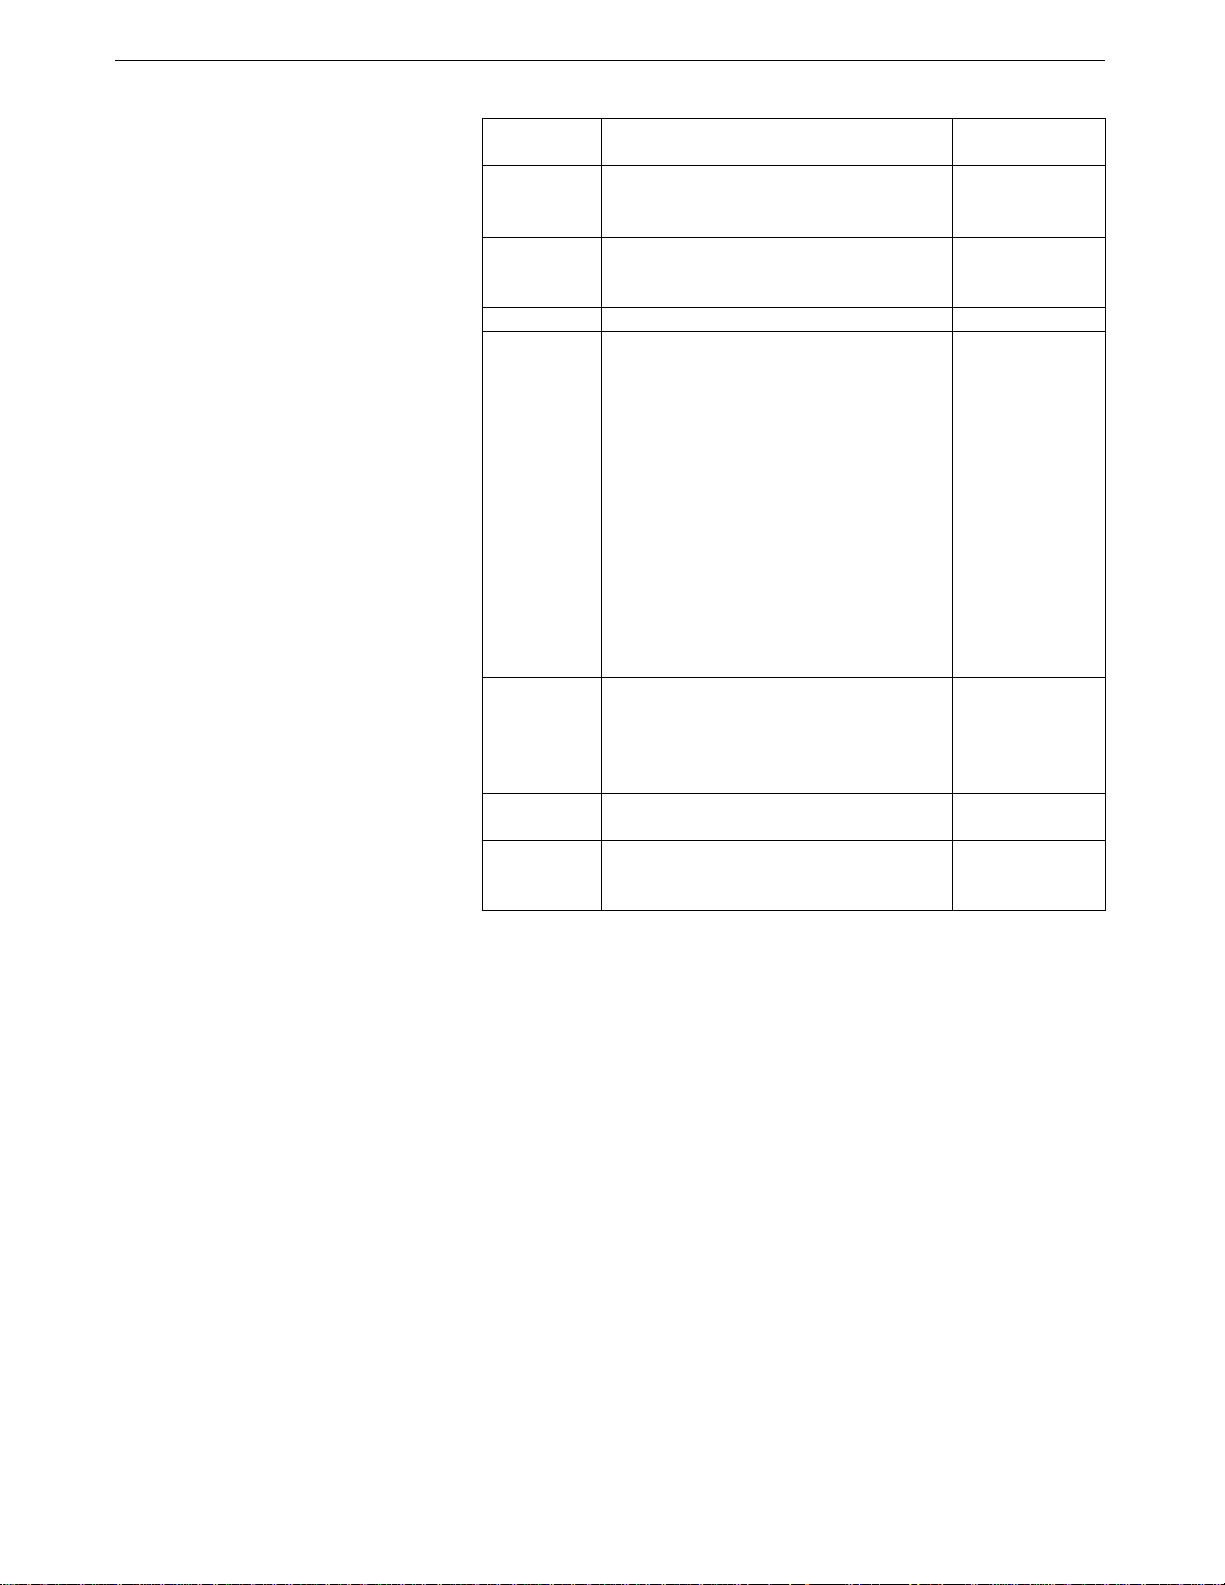
Following are the Toolbar buttons applicable to the FastCAT:
Toolbar
Button
Description
Equivalent
Command*
Re-establish communications with
Connect
FastCAT. Computer responds with
(press Enter key)
S> prompt.
Display instrument setup and status
Status
(configuration and setup parameters,
DS
whether FastCAT is sampling, etc.).
Coefficients Display calibration coefficients.
DCAL
Capture instrument responses on screen to
file; useful for diagnostics. File has .cap
extension. Capture status displays in
Status bar. Press Capture again to turn
off capture.
As FastCAT has no internal memory, if
you are using SEATERM to acquire
Capture
data you must capture before sampling
—
begins to save data for future review
and processing.
(Note: The .cap file does not have the
required header information for processing
by SBE Data Processing. Use SEASAVE
to acquire data that will be processed by
SBE Data Processing.)
Perform one or more diagnostic tests on
Diagnostics
FastCAT. Diagnostic test(s) accessed in
this manner are non-destructive –
they do not write over any existing
DS, DCAL,
and TS
instrument settings.
Stop
Interrupt and end current activity, such as
sampling or diagnostic test.
(press Esc key or
Ctrl C)
Free computer COM port used to
Disconnect
communicate with FastCAT. COM port
—
can then be used by another program.
*See Command Descriptions in Section 4: Deploying a nd Operating FastCAT.
14
Page 15
Section 3: Power and Communications Test
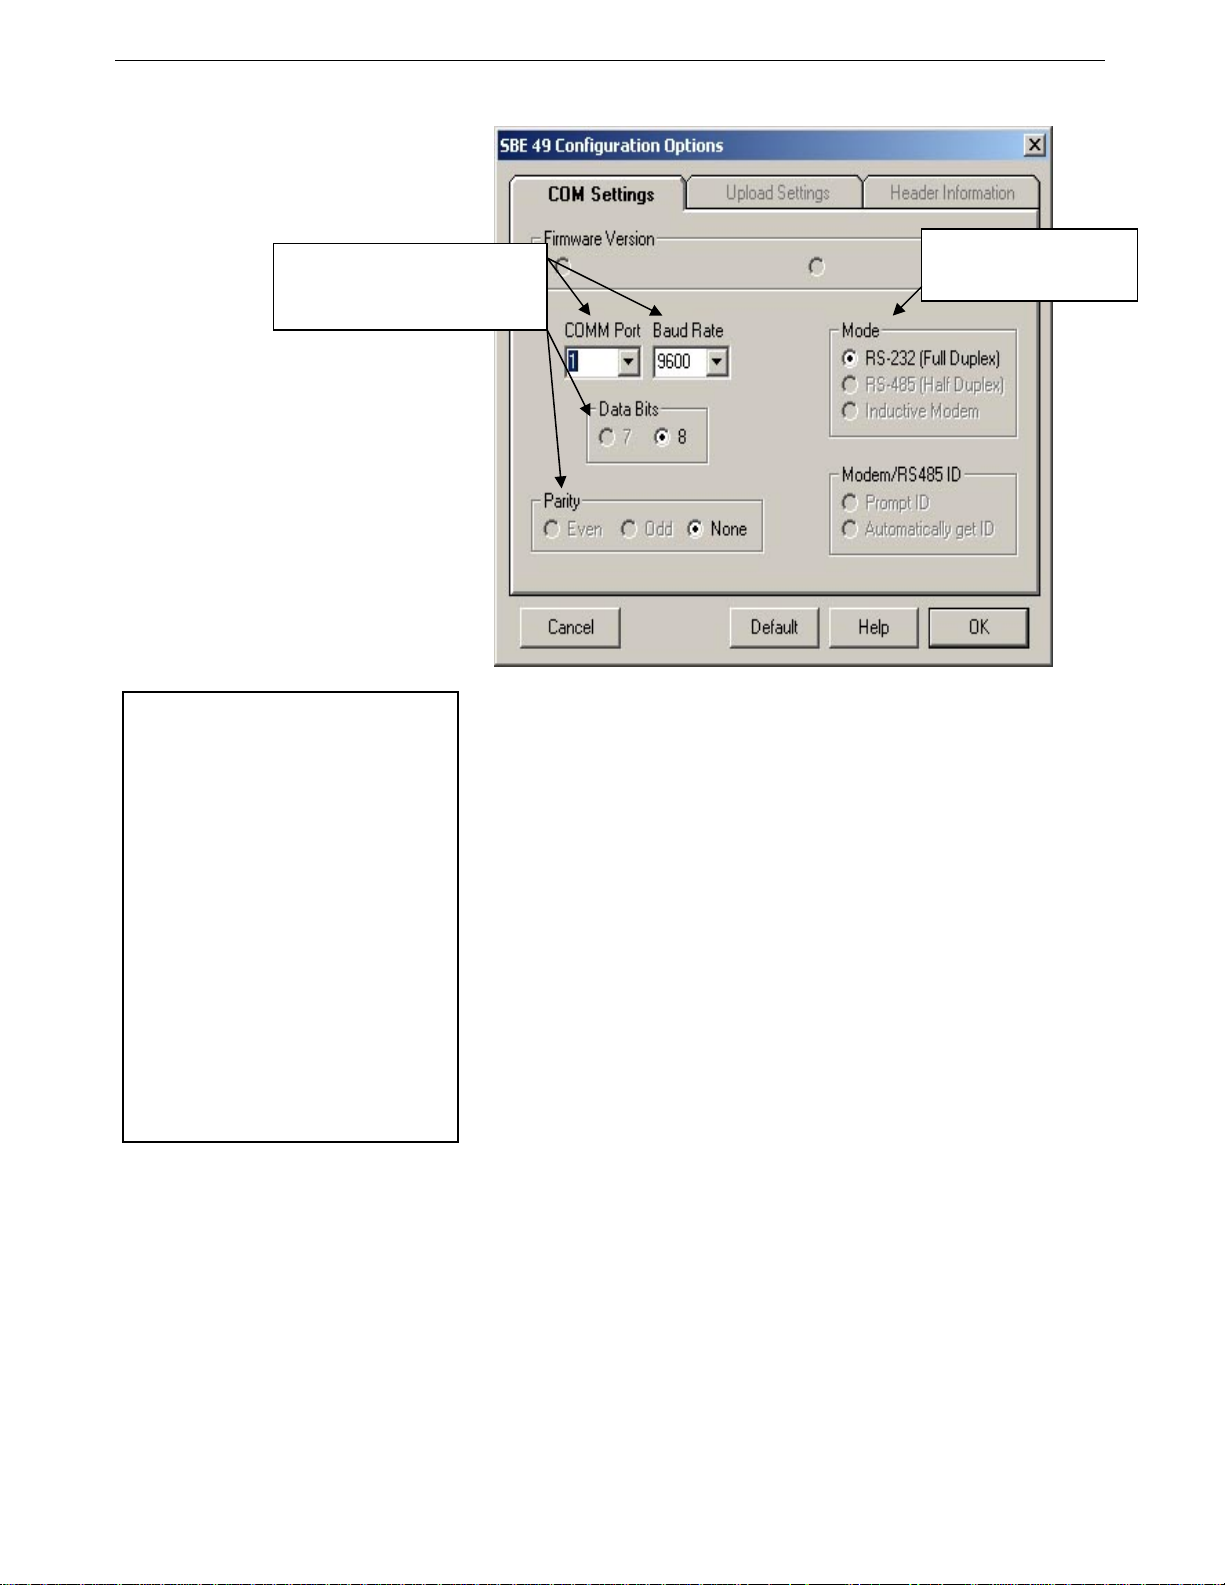
3. In the Configure menu, select SBE 49. The dialog box looks
like this:
Computer COM port, baud rate,
data bits, and parity for
communication between computer
and FastCAT
Note:
• SEATERM’s baud rate must be the
same as the FastCAT baud rate
(set with BAUD=). Baud is factory-
set to 9600, but can be changed by
the user (see Command
Descriptions in Section 4:
Deploying and Operating FastCAT).
• When you click OK, SEATERM
saves the Configuration Options
settings to the SeaTerm.ini file in
your Windows directory.
SeaTerm.ini contains the last saved
settings for each instrument. When
you open SEATERM and select the
desired instrument (SBE 37, 49,
etc.) in the Configure menu, the
Configuration Options dialog box
shows the last saved settings for
that instrument.
Interface for communication
between computer and
FastCAT
Make the selections in the Configuration Options dialog box:
• COMM Port: COM 1 through COM 10, as applicable
• Baud Rate: 9600 (documented on Configuration Sheet in manual)
• Data Bits: 8
• Parity: None
• Mode: RS-232 (Full Duplex)
Click OK to save the settings.
4. In the Communications menu, select Options / Cycle baud
when connecting.
5. Click Connect on the Toolbar. SEATERM tries to connect to the FastCAT
at the baud set in Step 3. If it cannot, it cycles through all other possible
baud rates to try to connect. When it connects, the display looks like this:
S>
This shows that correct communications between the computer and the
FastCAT has been established.
If the system does not respond with the S> prompt:
• Click Connect again.
• Verify the correct instrument was selected in the Configure menu and
the settings were entered correctly in the Configuration Options
dialog box. Note that the baud rate is documented on the
Configuration Sheet in the manual.
• Check cabling between the computer and FastCAT.
15
Page 16
Section 3: Power and Communications Test
6. Display FastCAT status information by clicking Status on the Toolbar.
The display looks like this:
SBE 49 FastCAT V 1.2 SERIAL NO. 0055
number of scans to average = 1
pressure sensor = strain gauge, range = 1000.0
minimum cond freq = 3000, pump delay = 30 sec
start sampling on power up = no
output format = converted decimal
output salinity = no, output sound velocity = no
temperature advance = 0.0625 seconds
celltm alpha = 0.03
celltm tau = 7.0
real-time temperature and conductivity correction enabled for converted data
7. Command the FastCAT to take a sample by typing TS and pressing the
Enter key. The display looks like this (with converted decimal output
format, and no output salinity or sound velocity):
23.7658, 0.00019, 0.062
where 23.7658 = temperature in degrees Celsius
0.00019 = conductivity in S/m
0.062 = pressure in decibars
These numbers should be reasonable; i.e., room temperature, zero
conductivity, barometric pressure (gauge pressure).
The FastCAT is ready for programming and deployment.
16
Page 17
Section 4: Deploying and Operating FastCAT
Section 4:
Deploying and Operating FastCAT
This section includes discussions of:
Note:
Help files contain detailed
information on setup and use of
Sea-Bird software.
• Sampling modes, including pump operation and example commands
• Real-time data corrections
• Baud rate, cable length, and data transmission rate
• Power and cable length
• Command descriptions
• Data output formats
• Optimizing data quality
• Setup for deployment
• Deployment
• Acquiring and processing FastCAT data
• Recovery - physical handling
Sampling Modes
The FastCAT has two sampling modes for obtaining data:
• Polled sampling
• Autonomous sampling
Descriptions and examples of the sampling modes follow. Note that the
FastCAT’s response to each command is not shown in the examples. Review
the operation of the sampling modes and the commands described in
Command Descriptions before setting up your system.
17
Page 18
Section 4: Deploying and Operating FastCAT
Polled Sampling
On command (TS), the FastCAT takes one sample and transmits the
data real-time.
The pump does not turn on automatically for polled sampling
(MINCONDFREQ= and PUMPDELAY= do not apply). To run the pump
before taking a sample, send PUMPON to turn the pump on before sending
TS. Send PUMPOFF to turn the pump off after taking the sample.
Example: Polled Sampling (user input in bold)
Apply power and wake up FastCAT. Set up to not start automatic
autonomous sampling when power is applied, to output data in
decimal engineering units format, and to output salinity and sound
velocity as well as conductivity, temperature, and pressure.
Verify setup with status command. Remove power.
(Apply power, then click Connect on Toolbar to wake up.)
S>AUTORUN=N
S>OUTPUTFORMAT=3
S>OUTPUTSAL=Y
S>OUTPUTSV=Y
S>DS (to verify setup)
(Remove power.)
When ready to take a sample, put FastCAT in water. Apply power
and wake up FastCAT. Command FastCAT to turn pump on, take
a sample, and turn pump off. Remove power. Repeat as desired.
(Apply power, then click Connect on Toolbar to wake up.)
S>PUMPON
S>TS
S>PUMPOFF
(Remove power.)
18
Page 19
Section 4: Deploying and Operating FastCAT
g
Autonomous Sampling
The FastCAT runs continuously, sampling data at 16 scans per second (16 Hz)
and transmitting the data real-time. The FastCAT can be set to average up to
255 samples, transmitting only the averaged data. AUTORUN defines how
autonomous sampling starts and stops:
If To Start Sampling To Stop Sampling
Turn on power.
Send START.
• Turn off power, or
• Send STOP, click Stop on
SEATERM’s Toolbar, or type
Ctrl Z. (Stopping this way allows
you to then send commands to
check or modify the setup.)
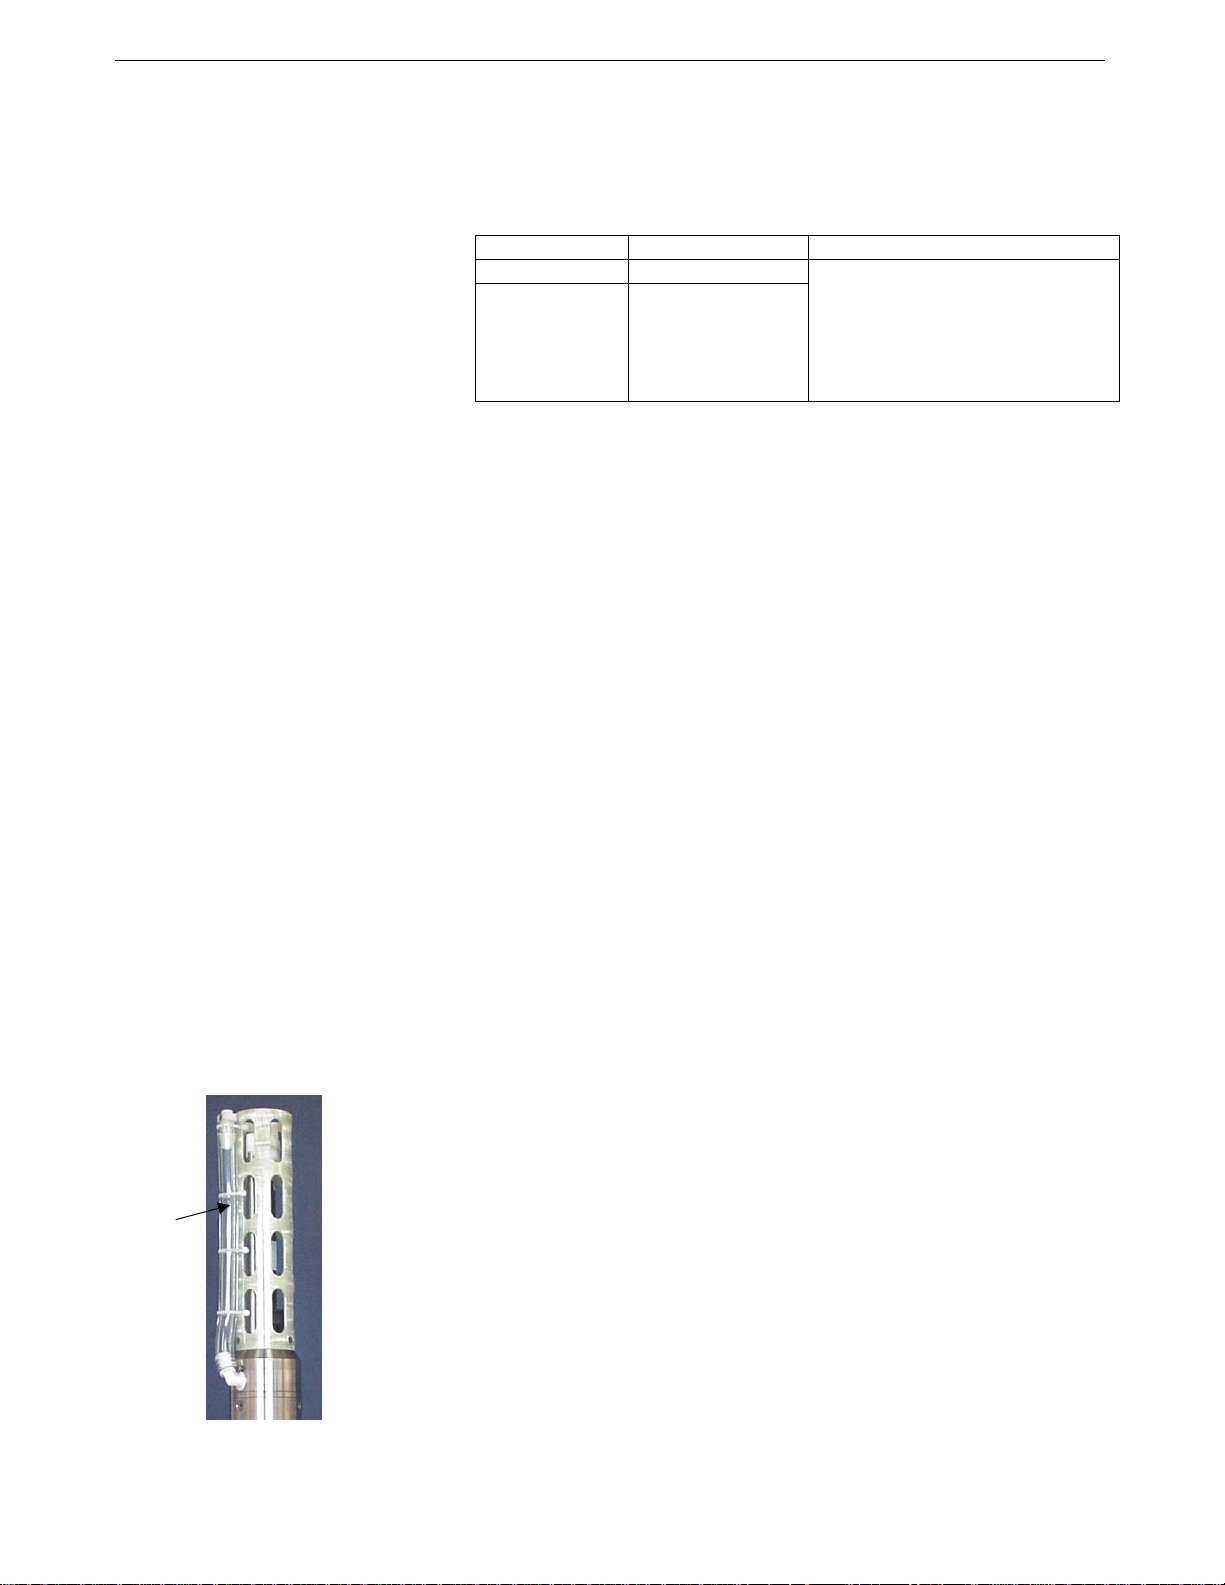
Pump
exhaust
tubin
AUTORUN=Y
AUTORUN=N
After the conductivity cell enters the water there is a user-programmable delay
before pump turn-on so that all the air in the pump tubing can escape. If the
pump motor turns on when there is air in the impeller housing, priming is
uncertain and a proper flow rate cannot be ensured. The cell inlet and pump
outlet must not come above the water surface or the prime will be lost.
• If prime is lost, stop sampling. Wait at least 5 seconds, then submerge the
FastCAT completely, restart sampling, and wait for the pump delay time
before beginning the profile.
Pump turn-on occurs when two user-programmable conditions have
been met:
• Raw conductivity frequency exceeds the minimum conductivity
frequency (MINCONDFREQ=)
Set the minimum conductivity frequency for pump turn-on above the
instrument’s zero conductivity raw frequency (shown on the FastCAT
Configuration Sheet in the manual), to prevent the pump from turning on
when the Fas tCAT is in air.
! For salt water and estuarine applications -
typical value = zero conductivity raw frequency + 500 Hz
! For fresh/nearly fresh water -
typical value = zero conductivity raw frequency + 5 Hz
If the minimum conductivity frequency is too close to the zero
conductivity raw frequency, the pump may turn on when the FastCAT is
in air as result of small drifts in the electronics. Some experimentation
may be required, and in some cases it may be necessary to rely only on the
pump turn-on delay time to control the pump. If so, set a minimum
conductivity frequency lower than the zero conductivity raw frequency.
• Pump turn-on delay time has elapsed (PUMPDELAY=)
Set the pump turn-on delay time to allow time for the pump to fill with
water after the FastCAT is submerged. Determine the turn-on delay by
immersing the FastCAT (power off, not sampling). Measure the time
needed to completely fill the pump exhaust tubing (by watching for when
air bubbles stop coming out of the exhaust); 20 seconds is typical. Set the
delay to approximately 1.5 times longer (30 seconds). When actually
using the FastCAT, be sure to soak the instrument just under the surface
for at least the time required for pump turn-on.
Pump turn-off occurs when the conductivity frequency falls below the
minimum conductivity frequency (MINCONDFREQ=).
19
Page 20
Section 4: Deploying and Operating FastCAT
Example 1: Autonomous Sampling Setup for AUTORUN=N (user input in bold)
Apply power and wake up FastCAT. Set up to average every 4 samples, and output
data in raw hexadecimal format. Set up with a 60-second pump turn-on delay after
pump enters water to ensure pump is primed before turning on. Verify setup with
status command. Remove power.
(Apply power, then click Connect on Toolbar to wake up.)
S>NAVG=4
S>OUTPUTFORMAT=0
S>PUMPDELAY=60
S>AUTORUN=N
S>DS (to verify setup)
(Remove power.)
Note:
Sea-Bird ships the
FastCAT with
AUTORUN=N (it will not
start sampling when power
is applied). If you send
AUTORUN=Y, turn power
off and then on again
to start sampling, or
send START.
When ready to begin sampling:
(Apply power, then click Connect on Toolbar to wake up.)
S>START
(Put FastCAT in water, and allow to soak for at least time required for pump turnon (PUMPDELAY=60) before begi nning cast.)
When cast is complete, stop sampling.
S>STOP
Example 2: Autonomous Sampling Setup for AUTORUN=Y (user input in bold)
Apply power. Set up to average every 4 samples, and output data in raw
hexadecimal format. Set up with a 60-second pump turn-on delay after pump enters
water to ensure pump is primed before turning on. Set up to start sampling upon
power up. Verify setup with status comm and.
(Apply power, then click Connect on Toolbar to wake up.)
S>NAVG=4
S>OUTPUTFORMAT=0
S>PUMPDELAY=60
S>AUTORUN=Y
S>DS (to verify setup)
(Remove power.)
When ready to begin sampling:
(Apply power.)
(Put FastCAT in water, and allow to soak for at least time required for pump turnon (PUMPDELAY=60) before begi nning cast.)
When cast is complete, remove power or send STOP to stop sampling (send
STOP if you want to view and/or modify FastCAT’s setup immediately after you
stop sampling).
20
Page 21
Section 4: Deploying and Operating FastCAT
Real-Time Data Corrections
Typical post-processing of CTD data includes the following:
• Aligning data − Data misalignment is caused by physical misalignment
of sensors in depth, inherent time delay of sensor responses, and water
transit time in a plumbing line. Aligning conductivity, temperature, and
pressure (C, T, and P) ensures that derived parameters are calculated with
measurements from the same parcel of water, eliminating spiking caused
by misaligned values in areas with sharp gradients.
• Filtering data − Filtering matches the T and C sensor time constants.
• Correcting for conductivity cell thermal mass − The glass cell stores
heat, causing water in the cell to be a different temperature than the
temperature sensor measured a moment earlier. Removing thermal mass
effects from measured conductivity provides improved results in areas
with steep temperature gradients.
Performing these calculations in post-processing allows you to make
adjustments to the measured data before calculating derived parameters.
SBE Data Processing, part of our SEASOFT suite, can perform this processing
on recorded data, if a complete C, T, and P time series is recorded. However, the
FastCAT, which samples and transmits data at 16 Hz, is frequently integrated
with an AUV or ROV. The AUV/ROV may record data on command, with
uneven time intervals between each recorded measurement. The lack of a true
time series from the FastCAT for these applications prevents aligning, filtering,
and correcting for cell thermal mass in post-processing.
Therefore, the FastCAT can be programmed to process data in real-time if
sampling autonomously. This provides C, T, and P output that is already
aligned, filtered, and corrected for cell thermal mass, and also provides
calculated and output salinity and sound velocity (if applicable) based on these
corrected values.
If real-time corrections are enabled (PROCESSREALTIME=Y) and the
Notes:
• The FastCAT does not perform
real-time corrections if the output
format is raw hex or raw decimal
(OUTPUTFORMAT=0 or 2), even
if PROCESSREALTIME=Y.
• See Appendix V: Real-Time Data
Correction Algorithms for details.
output format is converted hex or decimal (OUTPUTFORMAT=1 or 3), the
FastCAT processes the data as follows:
1. Advance temperature by user-programmed amount (TADVANCE=).
2. Filter temperature and conductivity with cosine filter and five-scan window.
3. Apply cell thermal mass correction to conductivity, with user-
programmed values for alpha (ALPHA=) and tau (TAU=).
4. Calculate averaged data (if NAVG= is greater than 1) based on corrected
values of C, T, and P.
5. Calculate salinity (if OUTPUTSAL=Y) and sound velocity (if
OUTPUTSV=Y) based on corrected, averaged values of C, T, and P.
Example: Autonomous Sampling Setup for Real-Time Data Processing (user input in bold)
See either of the autonomous sampling examples above for general setup. Send the following commands to enable and
establish parameters for real-time data processing: output converted decimal data, enable real-time data corrections,
advance temperature 0.0625 seconds, and use alpha and tau of 0.03 and 7 respectively, for cell thermal mass correction.
S>OUTPUTFORMAT=3
S>PROCESSREALTIME=Y
S>TADVANCE=0.0625
S>ALPHA=0.03
S>TAU=7
21
Page 22
Section 4: Deploying and Operating FastCAT
p
Baud, Cable Length, and Data Transmission Rate
Without a Sea-Bird Deck Unit
Notes:
• Baud rate is set with BAUD=.
• Real-time output rate is set
with NAVG=.
• Output format is set with
OUTPUTFORMAT=.
See Command Descri
Example 1 - What is fastest rate you can transmit real-time data over 800 m with OUTPUTFORMAT=0 (raw hex data)?
With 800 meters of cable, the FastCAT requires a baud rate of 1200 or less.
Number of characters for OUTPUTFORMAT=0 (from Data Output Formats) =
6 (T) + 6 (C) + 6 (P) + 4 (P temperature compensation) + 2 (carriage return & line feed) = 24
Time required to transmit data = (24 characters * 10 bits/character) / 1200 = 0.2 sec > 0.0625 sec (16 Hz, maximum sampling rate).
Therefore, set NAVG=4, averaging 4 measurements/sample and transmitting 1 sample every 0.25 seconds.
Example 2 – Same as above, but OUTPUTFORMAT=3 (engineering units in decimal), and OUTPUTSV=Y and OUTPUTSAL=Y
(output calculated salinity and sound velocity along with pressure, temperature, and conductivity).
Number of characters for OUTPUTFORMAT=3 (from Data Output Formats) =
8 (T) + 2 (comma & space) + 8 (C) + 2 (comma & space) + 8 (P) + 2 (comma & space) +
8 (salinity) + 2 (comma & space) + 8 (sound velocity) + 2 (carriage return & line feed) = 50
Time required to transmit data = (50 characters * 10 bits/character) / 1200 = 0.42 sec > 0.0625 sec (16 Hz, maximum sampling rate).
Therefore, set NAVG=7, averaging 7 measurements/sample and transmitting 1 sample every 0.4375 seconds.
tions.
The rate that real-time data can be transmitted from the FastCAT is dependent
on the amount of data to be transmitted per scan and the serial data baud rate:
Time required to transmit data =
(number of characters * 10 bits/character) / baud rate
where
Number of characters is dependent on included data and output format
(see Data Output Formats). Add 2 to the number of characters shown in
the output format, to account for the carriage return and line feed at the
end of each scan. For decimal output (OUTPUTFORMAT=2 or 3),
include decimal points, commas, and spaces when counting characters.
Time required to transmit data must be less than the real-time output rate.
Minimum baud rates are tabulated below for 16 Hz sampling (NAVG=1) and
8 Hz sampling (NAVG=2): (see Examples below for calculation examples)
NAVG OUTPUTFORMAT Minimum Baud
1
2
0 or 1 4800
2 or 3* 9600
0 or 1 2400
2 or 3* 4800
* Including output of salinity and soun d vel o ci ty.
The length of cable that the FastCAT can drive to transmit real-time data is
also dependent on the baud rate. The allowable combinations are:
Maximum Cable
Length (meters)
Maximum Baud
1600 800 400 200 100 50 25
600 1200 2400 4800 9600 19200 38400
With a Sea-Bird Deck Unit
Set the FastCAT baud rate to 4800 if using the FastCAT with the SBE 36 CTD
Deck Unit and PDIM. The data telemetry link can drive 10,000 meters of
cable while accepting 4800 baud serial data. The relationship between rate of
transmission, amount of data to be transmitted, and baud rate is as described
above for a FastCAT without a Deck Unit.
Example – FastCAT with SBE 36 and PDIM. What is fastest rate you can transmit data over 800 m with OUTPUTFORMAT=0 (raw hex
data, which is the required output format for use with the Deck Unit)?
With a Deck Unit, the FastCAT requires a baud rate of 4800.
Number of characters for OUTPUTFORMAT=0 (from Data Output Formats) =
6 (T) + 6 (C) + 6 (P) + 4 (P temperature compensation) + 2 (carriage return & line feed) = 24
Time required to transmit data = (24 characters * 10 bits/character) / 4800 = 0.05 sec < 0.0625 sec (16 Hz, maximum sampling rate).
Therefore, set NAVG=1, providing 16 Hz data (1 sample every 0.0625 seconds).
22
Page 23
Section 4: Deploying and Operating FastCAT
Power and Cable Length for FastCAT without Deck Unit
Note:
Common wire resistances:
Gauge Resistance (ohms/foot)
12 0.0016
14 0.0025
16 0.0040
18 0.0064
19 0.0081
20 0.0107
22 0.0162
24 0.0257
26 0.0410
28 0.0653
There are two issues to consider:
• Limiting the IR loss during communication with the controller to 1 volt;
higher IR loss will prevent the instrument from transmitting real-time data
because of the difference in ground potential.
• Supplying enough power at the power source so that sufficient power
is available at the instrument after considering IR loss from the
turn-on transient.
Each issue is discussed below.
Limiting IR Loss to 1 Volt
The limit to cable length is typically reached when the maximum current
during communication times the power common wire resistance is more than
1 volt, because the difference in ground potent ia l of the Fast C AT and
controller prevents the FastCAT from transmitting real-time data.
= 1 volt = IR
V
limit
Maximum cable length = R
limit
/ wire resistance per foot
limit
where I = current required by FastCAT during communication.
The value for I varies, depending on the input voltage –
• 390 mA at 9 V
• 285 mA at 12 V
• 180 mA at 19 V
See Specifications in Section 2: Description of FastCAT.
Example – For 12 volt power supply and 20 gauge wire, what is the maximum distance to transmit po wer to the FastCAT
when considering communication IR loss?
At 12 V, I = 0.285 Amps
R
= V
limit
For 20 gauge wire, resistance is 0.0107 ohms/foot.
Therefore, maximum cable length is 3.5 ohms / 0.0107 ohms/foot = 327 feet = 100 meters.
Note that 100 meters < 800 meters (limit to distance FastCAT can transmit data at 1200 baud, as shown in example in
Baud, Cable Length, and Data Transmission Rate), so cable is limited to 100 meters because of power constraints.
Alternatively, you can transmit data over 800 meters but provide a power source closer to the FastCAT.
/ I = 1 volt / 0.285 Amps = 3.5 ohms
limit
Supplying Enough Power to FastCAT
Another consideration in determining maximum cable length is supplying
enough power at the power source so that sufficient voltage is available, after
IR loss in the cable (from the 0.75 Amp turn-on transient, two-way
resistance), to power the FastCAT. Provide at least 9 volts, after IR loss.
V - IR >
9 volts
where I = FastCAT turn-on transient (0.75 Amps; see Specifications in
Section 2: Description of FastCAT).
Example 1 – For 20 gauge wire, what is maximum distance to transmit power to FastCAT if using 12 volt power source?
V - IR >
3 volts >
Note that 57 meters < 100 meters (maximum distance when considering communication IR loss), so supplying enough
power during power-on transient is controlling factor for this example. Using a different wire gauge would increase
allowable cable length.
Example 2 – Same as above, but there are 4 FastCATs powered from same power supply.
V - IR > 9 volts 12 volts - (0.75 Amps * 4 FastCATs) * (0.0107 ohms/foot * 2 * cable length) > 9 volts
3 volts >
Cable length <
9 volts 12 volts - (0.75 Amps) * (0.0107 ohms/foot * 2 * cable length) > 9 volts
(0.75 Amps) * (0.0107 ohms/foot * 2 * cable length) Cable length < 187 ft = 57 meters
(0.75 Amps * 4 FastCATs) *(0.0107 ohms/foot * 2 * cable length)
46 ft = 14 meters (to FastCAT furthest from power source)
23
Page 24
Section 4: Deploying and Operating FastCAT
Command Descriptions
This section describes commands and provides sample outputs.
See Appendix III: Command Summary for a summarized command list.
When entering commands:
• Input commands to the FastCAT in upper or lower case letters and
register commands by pressing the Enter key.
• The FastCAT sends ?CMD if an invalid command is entered.
• If the system does not return an S> prompt after executing a command,
press the Enter key to get the S> prompt.
• Establish communications by pressing Connect on the Toolbar or the
Enter key to get an S> prompt.
• If the FastCAT is transmitting data and you want to stop it, send STOP,
click Stop on the Toolbar, or type Ctrl Z. Press the Enter key to get the
S> prompt.
• The FastCAT responds only to DS, DCAL, and STOP while sampling. If
you interrupt the FastCAT while it is sampling (for example, to send DS),
it will temporarily stop sampling. Sampling resumes after it responds to
the command.
Entries made with the commands are permanently stored in the FastCAT and
remain in effect until you change them.
24
Page 25
Section 4: Deploying and Operating FastCAT
Status Command
DS Display operating status and
setup parameters.
Equivalent to Status on Toolbar.
List below includes, where applicable,
command used to modify parameter.
• firmware version, serial number
• number of scans to average [NAVG=]
• pressure sensor type and
range [PRANGE=]
• minimum conductivity frequency for
pump turn-on [MINCONDFREQ=]
and pump turn-on delay
[PUMPDELAY=]
• start autonomous sampling
automatically when power applied
[AUTORUN=]?
• output format
[OUTPUTFORMAT=]
• output salinity [OUTPUTSAL=] and
sound velocity [OUTPUTSV=] with
each sample? (only if
OUTPUTFORMAT=3)
• time to advance temperature to align
with conductivity [TADVANCE=]
Note:
If PROCESSREALTIME=Y but
OUTPUTFORMAT=0 or 2 (output
raw hexadecimal or raw decimal
data), the status reply shows:
real-time temperature and
conductivity correction
enabled, not applied
to raw data,
and the FastCAT does not perform
real-time corrections.
• conductivity cell thermal mass alpha
correction [ALPHA=]
• conductivity cell thermal mass tau
correction [TAU=]
• enable real-time corrections
[PROCESSREALTIME=]?
Example: Status (DS) command (user input in bold; command used to modify parameter in parentheses)
S>DS
SBE 49 FastCAT V 1.2 SERIAL NO. 0055
number of scans to average = 1 [NAVG=]
pressure sensor = strain gauge, range = 1000.0 [PRANGE=]
minimum cond freq = 3000, pump delay = 30 sec [MINCONDFREQ=, PUMPDELAY=]
start sampling on power up = no [AUTORUN=]
output format = converted decimal [OUTPUTFORMAT=]
output salinity = yes, output sound velocity = yes [OUTPUTSAL=, OUTPUTSV=]
temperature advance = 0.0625 seconds [TADVANCE=]
celltm alpha = 0.03 [ALPHA=]
celltm tau = 7.0 [TAU=]
real-time temperature and conductivity correction enabled for converted data [PROCESSREALTIME=]
25
Page 26
Section 4: Deploying and Operating FastCAT
Setup Commands
Notes:
• The FastCAT’s baud rate (set with
BAUD=) must be the same as
SEATERM’s baud rate (set in the
Configure menu).
• The minimum baud is dependent on
sampling rate (NAVG=) and output
format (OUTPUTFORMAT=).
See Baud, Cable Length, and
Data Transmission Rate and
Data Output Formats.
BAUD=x x= baud rate (1200, 2400, 4800, 9600,
19200, or 38400). Default 9600.
OUTPUTFORMAT=x x= 0: Output raw freque nci es, A/D counts,
Note:
Sea-Bird’s real-time data acquisition
software (SEASAVE) requires data in
raw hexadecimal
Before beginning a cast:
• If you will be using SEASAVE to
view and save real-time data for
future processing by SBE Data
Processing - You must set output
format to raw hex.
• If you will be using SEATERM to
view and capture real-time data
(cannot be processed by SBE Data
Processing) - Set output format to
converted decimal for ease in
viewing data.
The FastCAT does not perform realtime corrections if the output format is
raw hex or raw decimal
(OUTPUTFORMAT=0 or 2), even if
PROCESSREALTIME=Y.
(OUTPUTFORMAT=0).
and voltages in Hexadecimal form. Must
use this format for acquiring, viewing,
and saving real-time data in SEASAVE.
SEASAVE creates a data file that can
be processed with SBE Data Processing
(see Acquiring and Processing
Real-Time Data with SEASAVE and
SBE Data Processing).
x= 1: Output converted (engineering units)
data in Hexadecimal form.
x= 2: Output raw data in decimal form.
x= 3: Output converted (engineering units)
data in decimal form. Must use this format
to output salinity or sound velocity. If
logging data to ROV, AUV, etc., use this
format if you want to process saved data
with SBE Data Processing (see Acquiring
Real-Time Data with ROV, AUV, etc. for
Processing by Sea-Bird Software).
Default.
OUTPUTSAL=x x= Y: Calculate and output salinity (psu).
Only applies if OUTPUTFORMAT=3.
Default.
x= N: Do not calculate and output salinity.
OUTPUTSV=x x= Y: Calculate and output sound velocity
(m/sec), using Chen and Millero formula
(UNESCO Technical Papers in Marine
Science #44). Only applies if
OUTPUTFORMAT=3. Default.
x= N: Do not calculate and output
sound velocity.
Note:
See Autonomous Sampling
Commands below for NAVG=,
MINCONDFREQ=, PUMPDELAY=,
PROCESREALTIME=, TADVANCE=,
ALPHA=, TAU=, and AUTORUN=
descriptions; these commands apply
only to autonomous sampling.
SETDEFAULTS Reset following to default values:
• OUTPUTFORMAT=3
• OUTPUTSAL=Y
• OUTPUTSV=Y
• NAVG=1
• MINCONDFREQ=3000
• PUMPDELAY=30
• PROCESSREALTIME=Y
• TADVANCE=0.0625
• ALPHA=0.03
• TAU=7.0
• AUTORUN=N
26
Page 27
Section 4: Deploying and Operating FastCAT
Note:
In SEATERM, to save real-time
data to a file, click Capture on
the Toolbar before beginning
sampling.
Autonomous Sampling Commands
Autonomous sampling directs the FastCAT to sample data at 16 Hz and
transmit the data real-time. The FastCAT can be set to average up to
255 samples, transmitting only the averaged data. AUTORUN defines how
autonomous sampling starts and stops:
IF To Start Sampling To Stop Sampling
AUTORUN=N
(default)
Send START.
• Turn off power, or
• Send STOP, click Stop on
SEATERM’s Toolbar, or type
AUTORUN=Y
Turn on power.
Ctrl Z. (Stopping this way allows
you to then send commands to
check or modify the setup.)
NAVG=x x= number of samples to average
(default 1, maximum 255). FastCAT
samples at 16 Hz (every 0.0625 seconds)
and averages NAVG samples; averaged
data is transmitted real-time.
Example: If NAVG=8, FastCAT averages data from 8 samples
(= 1 average/0.5 second) and transmits averaged data real-time.
MINCONDFREQ=x x= minimum conductivity frequency (Hz)
to enable pump turn-on, to prevent pump
from turning on before FastCAT is in
water. Pump stops when frequency drops
below MINCONDFREQ.
FastCAT Configuration Sheet in manual
lists uncorrected (raw) frequency output at
0 conductivity. Typical value (factory-set)
for MINCONDFREQ for
salt water and estuarine application is:
(0 conductivity frequency + 500 Hz).
Typical value for MINCONDFREQ for
fresh water applications is:
(0 conductivity frequency + 5 Hz).
Default 3000 Hz.
PUMPDELAY=x x= time (seconds) to wait after minimum
conductivity frequency
(MINCONDFREQ) is reached before
turning pump on. Pump delay time allows
time for tubing and pump to fill with water
after FastCAT is submerged. Pump starts
PUMPDELAY seconds after conductivity
cell’s frequency output is greater than
MINCONDFREQ. Default 30 seconds.
27
Page 28
Section 4: Deploying and Operating FastCAT
Autonomous Sampling Commands (continued)
Notes:
• See Real-Time Data Corrections
for detailed explanations of
PROCESSREALTIME=,
TADVANCE=, ALPHA=,
and TAU=.
• If PROCESSREALTIME=Y but
OUTPUTFORMAT=0 or 2 (output
raw hex or raw decimal data), the
status reply shows:
real-time temperature
and conductivity
correction enabled, not
applied to raw data,
and the FastCAT does not
perform real-time corrections.
PROCESSREALTIME=x x= Y: Apply alignment, filtering, and
conductivity cell thermal mass corrections
to real-time data. Only applies if
OUTPUTFORMAT=1 or 3. Default.
x= N: Do not apply corrections to data.
TADVANCE=x x= Time to advance temperature data
relative to conductivity and pressure data.
Range 0 to 0.125 seconds; default
0.0625 seconds. Only applies if
PROCESSREALTIME=Y and
OUTPUTFORMAT=1 or 3.
ALPHA=x
x= Conductivity cell thermal mass
alpha correction. Range 0.02 to 0.05;
default 0.03. Only applies if
PROCESSREALTIME=Y
OUTPUTFORMAT=1 or 3.
TAU=x x= Conductivity cell thermal mass tau
correction. Range 5.0 to 10.0; default 7.0.
Only applies if
PROCESSREALTIME=Y
OUTPUTFORMAT=1 or 3.
AUTORUN=x x=N: Wait for a command when power is
Note:
After you send AUTORUN=Y,
to start sampling immediately:
• turn power off and then on again,
or
• send START.
applied. Default.
x=Y: Start autonomous sampling
automatically when power is applied.
START Start autonomous sampling now
(applicable if AUTORUN=N or if you
just sent AUTORUN=Y).
Notes:
• You may need to send STOP
several times to get the FastCAT
to respond.
• You can also stop autonomous
sampling by clicking the Stop key
on the Toolbar, typing Ctrl Z, or
removing power.
STOP Stop autonomous sampling.
Press Enter key to get S> prompt
before entering STOP.
28
Page 29
Section 4: Deploying and Operating FastCAT
Polled Sampling Commands
PUMPON Turn pump on. Use this command:
• Before sending TS to obtain pumped
conductivity data, or
• To test pump.
PUMPOFF Turn pump off.
TS Take 1 sample and transmit data.
Testing Commands
Note:
Testing commands do not
automatically turn the pump on.
Thus, they report conductivity from
essentially the same sample of
water for all 100 samples, because
the pump does not run and water
does not freely flow through the
conductivity cell. To get conductivity
from fresh samples, send PUMPON
before sending TC or TCR, and
then send PUMPOFF when the test
is complete.
The FastCAT takes and transmits data for 100 samples for each test. Press the
Esc key or Stop on the Toolbar to stop a test.
TT Measure temperature, transmit
converted data.
TC Measure conductivity, transmit
converted data.
TP Measure pressure, transmit converted data.
TTR Measure temperature, transmit raw data.
TCR Measure conductivity, transmit raw data.
TPR Measure pressure, transmit raw data.
29
Page 30
Section 4: Deploying and Operating FastCAT
Coefficients Commands
DCAL Display calibration coefficients.
Equivalent to Coefficients on Toolbar.
Notes:
• Dates shown are when
calibrations were performed.
Calibration coefficients are
initially factory-set and should
agree with Calibration Certificate
shipped with FastCAT.
• See individual Coefficient
Commands below for definitions
of the data in the example.
Example: Display coefficients for FastCAT (user input in bold).
S>dcal
SBE 49 FastCAT V 1.2 SERIAL NO. 0055
temperature: 26-apr-01
TA0 = -3.178124e-06
TA1 = 2.751603e-04
TA2 = -2.215606e-06
TA3 = 1.549719e-07
TOFFSET = 0.000000e+00
conductivity: 26-apr-01
G = -9.855242e-01
H = 1.458421e-01
I = -3.290801e-04
J = 4.784952e-05
CPCOR = -9.570000e-08
CTCOR = 3.250000e-06
CSLOPE = 1.000000e+00
Pressure S/N = 023674, range = 1000 psia: 25-apr-01
PA0 = -6.893561e-01
PA1 = 1.567975e-02
PA2 = -6.637727e-10
PTCA0 = 5.246558e+05
PTCA1 = -4.886082e+00
PTCA2 = 1.257885e-01
PTCB0 = 2.489275e+01
PTCB1 = -8.500000e-04
PTCB2 = 0.000000e+00
PTEMPA0 = -6.634546e+01
PTEMPA1 = 5.093069e+01
PTEMPA2 = 1.886260e-01
POFFSET = 0.000000e+00
Use the commands listed below to modify a particular coefficient or date:
Note:
F = floating point number
S = string with no spaces
Temperature
TCALDATE=S S=calibration date
TA0=F F=A0
TA1=F F=A1
TA2=F F=A2
TA3=F F=A3
TOFFSET=F F=offset correction
Conductivity
CCALDATE=S S=calibration date
CG=F F=G
CH=F F=H
CI=F F=I
CJ=F F=J
CPCOR=F F=pcor
CTCOR=F F=tcor
CSLOPE=F F=slope correction
Pressure
PCALDATE=S S=calibration date
PRANGE=F F=sensor full scale range (psi)
POFFSET=F F=offset correction
PA0=F F=A0
PA1=F F=A1
PA2=F F=A2
PTEMPA0=F F=pressure temperature A0
PTEMPA1=F F=pressure temperature A1
PTEMPA2=F F=pressure temperature A2
PTCA0=F F=pressure temperature compensation ptca0
PTCA1=F F=pressure temperature compensation ptca1
PTCA2=F F=pressure temperature compensation ptca2
PTCB0=F F=pressure temperature compensation ptcb0
PTCB1=F F=pressure temperature compensation ptcb1
PTCB2=F F=pressure temperature compensation ptcb2
30
Page 31
Section 4: Deploying and Operating FastCAT
Data Output Formats
Note:
See Baud, Cable Length, and Data
Transmission Rate for the
interaction of output format, data
transmission rate, baud rate, and
cable length.
Notes:
• If you will be using SEASAVE to
acquire real-time data, set
OUTPUTFORMAT=0.
• For real-time data processing, set
OUTPUTFORMAT=1 or 3 and
PROCESSREALTIME=Y.
• Our software uses the equations
shown to perform these
calculations; alternatively, use
the equations to develop your
own processing software. After
the data is converted to A/D
counts, frequencies, and volts,
our software uses the sensor
calibration coefficients and the
equations on the sensor
calibration sheets to convert to
engineering units.
• The FastCAT’s pressure sensor
is an absolute sensor, so its raw
output includes the effect of
atmospheric pressure (14.7 psi).
As shown on the Calibration
Sheet, Sea-Bird’s calibration (and
resulting calibration coefficients)
is in terms of psia. However,
when outputting pressure in
engineering units, the FastCAT
outputs pressure relative to the
ocean surface (i.e., at the surface
the output pressure is
0 decibars). The FastCAT uses
the following equation to convert
psia to decibars:
Pressure (db) =
[pressure (psia) - 14.7] * 0.689476
Output format is dependent on OUTPUTFORMAT (=0, 1, 2, or 3). Each line
of data is ended with a carriage return and line feed.
OUTPUTFORMAT=0 (raw data in Hexadecimal)
Data is output in the order listed, with no spaces or commas between
parameters. Shown with each parameter is the number of digits, and how to
calculate the parameter from the data (use the decimal equivalent of the hex
data in the equations).
1. Temperature A/D counts = tttttt
2. Conductivity frequency (Hz) = cccccc / 256
3. Pressure sensor pressure A/D counts = pppppp
4. Pressure sensor temperature compensation voltage = vvvv / 13,107
Example: example scan = ttttttccccccppppppvvvv = 0A53711BC7220C14C17D82
• Temperature = tttttt = 0A5371 (676721 decimal);
temperature A/D counts = 676721
• Conductivity = cccccc = 1BC722 (1820450 decimal);
conductivity frequency = 1820450 / 256 = 7111.133 Hz
• Pressure = pppppp = 0C14C1 (791745 decimal);
pressure A/D counts = 791745
• Pressure temperature compensation =
vvvv = 7D82 (32,130 decimal);
pressure temperature = 32,130 / 13,107 = 2.4514 volts
OUTPUTFORMAT=1 (engineering units in Hexadecimal)
Data is output in the order listed, with no spaces or commas between the
parameters. Shown with each parameter is the number of digits, and how to
calculate the parameter from the data (use the decimal equivalent of the
hexadecimal data in the equations).
Note that if PROCESSREALTIME=Y, the output data has been alig ne d,
filtered, and corrected for cell thermal mass effects.
1. Temperature (°C, ITS-90) = (tttttt / 100,000) - 10
2. Conductivity (S/m) = (cccccc / 1,000,000) - 1
3. Pressure (decibars) = (pppppp / 1,000) - 100
Example: example scan = ttttttccccccpppppp = 3385C40F42FE0186DE
• Temperature = tttttt = 3385C4 (3376580 decimal);
temperature (°C, ITS-90) = (3376580 / 100,000) - 10 = 23.7658
• Conductivity = cccccc = 0F42FE (1000190 decimal);
conductivity (S/m) = (1000190 / 1,000,000) - 1 = 0.00019
• Pressure = pppppp = 0186DE (100062 decimal);
pressure (decibars) = (100062 / 1,000) - 100 = 0.062
31
Page 32
Section 4: Deploying and Operating FastCAT
OUTPUTFORMAT=2 (raw data in decimal)
Data is output in the order listed, with a comma followed by a space between
each parameter. Shown with each parameter are the number of digits and the
placement of the decimal point. Leading zeros are suppressed, except for one
zero to the left of the decimal point.
1. Temperature A/D counts = tttttt
2. Conductivity frequency (Hz) = cccc.ccc
3. Pressure sensor pressure A/D counts = pppppp
4. Pressure sensor temperature compensation voltage = v.vvvv
Example: example scan = tttttt, cccc.ccc, pppppp, v.vvvv = 676721, 7111.133, 791745, 2.4514
• Temperature = tttttt = 676721;
temperature A/D counts = 676721
• Conductivity = cccc.ccc = 7111.133;
conductivity frequency = 7111.133 Hz
• Pressure = pppppp = 791745;
Pressure A/D counts = 791745
• Pressure temperature compensation = v.vvvv = 2.4514;
Pressure temperature = 2.4514 volts
OUTPUTFORMAT=3 (engineering units in decimal)
Data is output in the order listed, with a comma followed by a space between
each parameter. Shown with each parameter are the number of digits and the
placement of the decimal point. Leading zeros are suppressed, except for one
zero to the left of the decimal point.
Note that if PROCESSREALTIME=Y, the output data has been alig ne d,
filtered, and corrected for cell thermal mass effects.
1. Temperature (°C, ITS-90) = ttt.tttt
2. Conductivity (S/m) = cc.ccccc
3. Pressure (decibars) = pppp.ppp
4. Salinity (psu) = sss.ssss (if OUTPUTSAL=Y)
5. Sound velocity (meters/second) = vvvv.vvv (if OUTPUTSV=Y)
Example: FastCAT with OUTPUTSAL=N, OUTPUTSV=N
example scan = ttt.tttt, cc.ccccc, pppp.ppp = 23.7658, 0.00019, 0.062
• Temperature = ttt.tttt = 23.7658;
temperature (°C, ITS-90) = 23.7658
• Conductivity = cc.ccccc = 0.00019;
conductivity (S/m) = 0.00019
• Pressure = pppp.ppp = 0.062;
pressure (decibars) = 0.062
32
Page 33
Section 4: Deploying and Operating FastCAT
Optimizing Data Quality
This section contains guidelines for obtaining the best quality data. So me of
these guidelines may conflict with the goals of a particular application, but you
should be aware of the tradeoffs of data quality vs. mission goals.
FastCAT Orientation and Pump Use
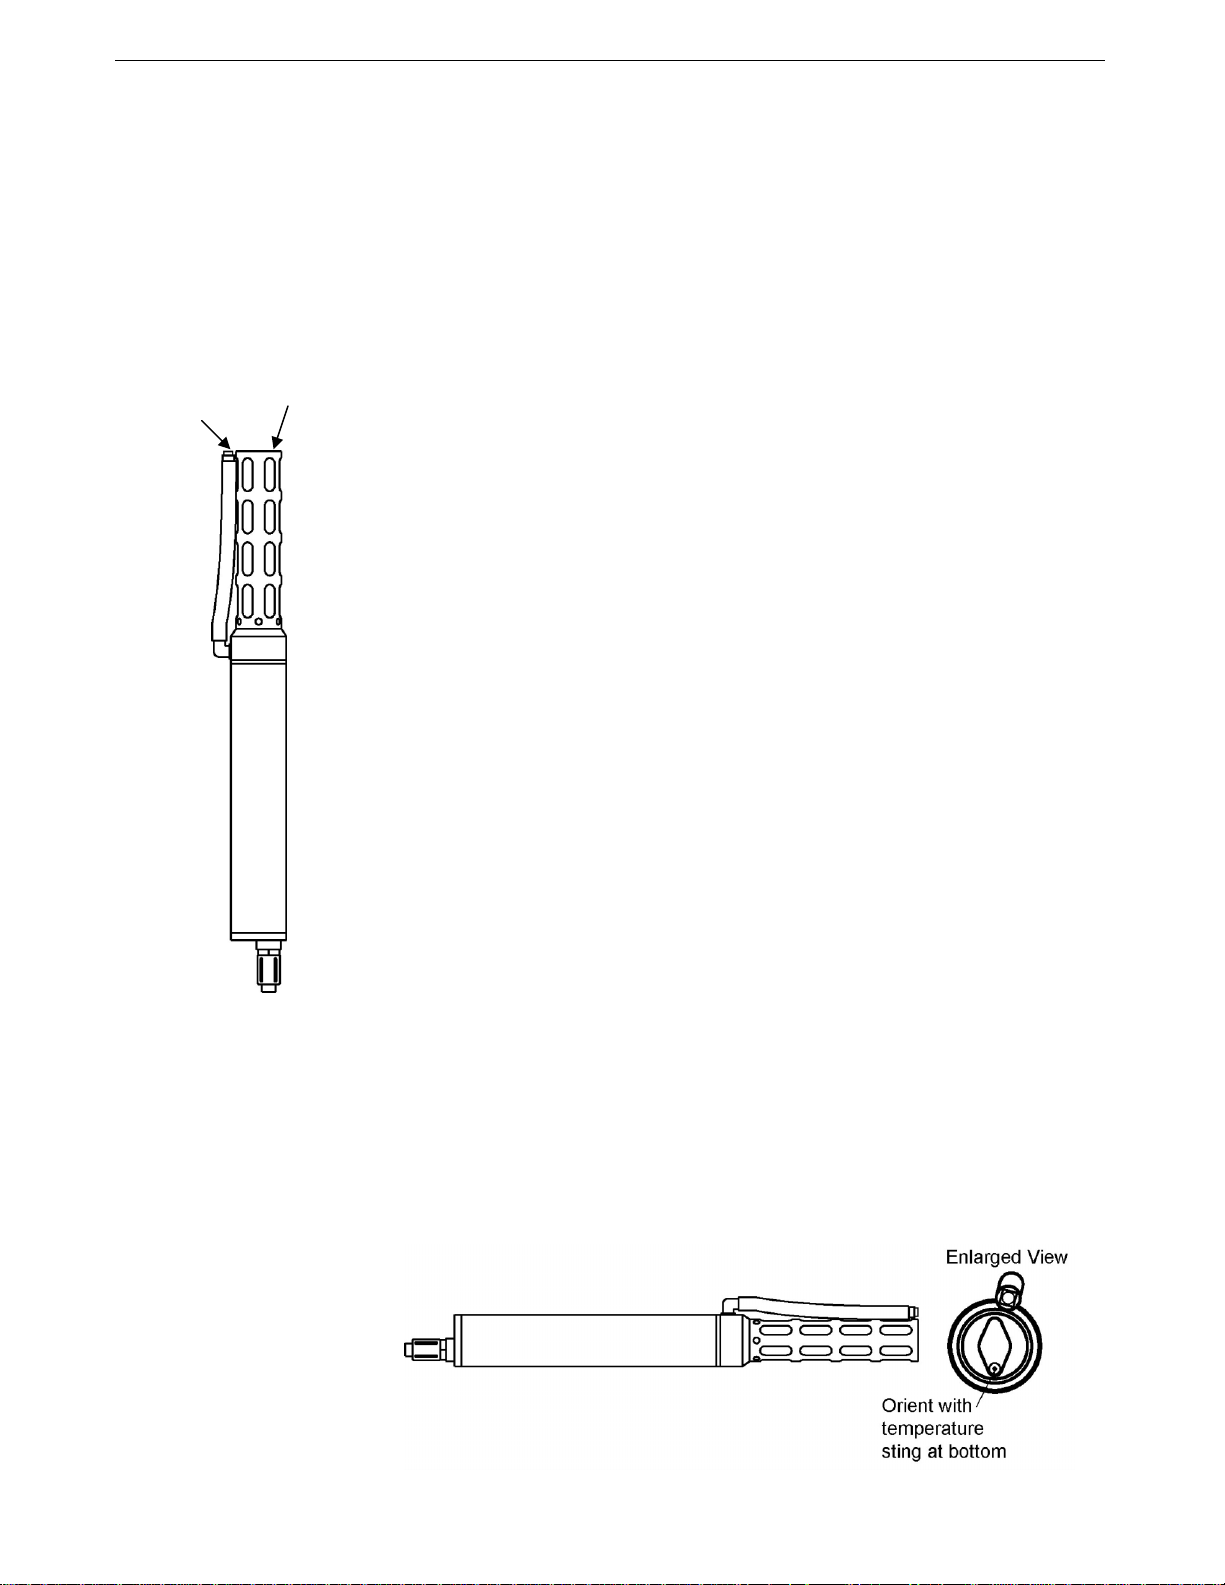
Vertical Orientation, Upcast Data
Pump exhaust
plumbing
and outlet
Sensor
intake
The FastCAT is designed for obtaining upcast data when deployed in a
vertical, sensors-up orientation. This o rientation, combined with the external
pump exhaust plumbing, provides a U-shape to the system plumbing. The
U-shape and the FastCAT’s good seals, combined with optimal pump
operation, can prevent surface oils and other contaminants from getting into
the plumbing and conductivity cell. These oils and contaminants are the
primary cause of calibration drift in conductivity sensors.
Pump operation to prevent intrusion of surface oils and contaminants follows:
1. On Deployment -
When not in use, store the FastCAT dry (see Section 5: Routine
Maintenance and Calibration). Fill the cell with a 0.1% solution of Triton
1 hour before deployment. Deploy the FastCAT without removing the
Triton solution. As the FastCAT breaks the surface, oils and other
surface contaminants will float on the Triton solution at the intake and
exhaust, preventing contaminants from getting into the plumbing and
conductivity cell. Hold the FastCAT below the surface until the pump
turns on, expelling the Triton solution and drawing in seawater.
2. On Recovery -
Turn off the pump before the FastCAT reaches the surface (if sampling
autonomously, stop sampling to turn off the pump). Water will be held in
the U-shaped plumbing. As the FastCAT breaks the surface, oils and other
surface contaminants will float on the water at the intake and exhaust,
preventing contaminants from getting into the plumbing and conductivity
cell. Turn over the FastCAT when it is on deck, emptying the water from
the conductivity cell and exhaust plumbing, so the oil floating on the
intake and exhaust surfaces does not get into the system.
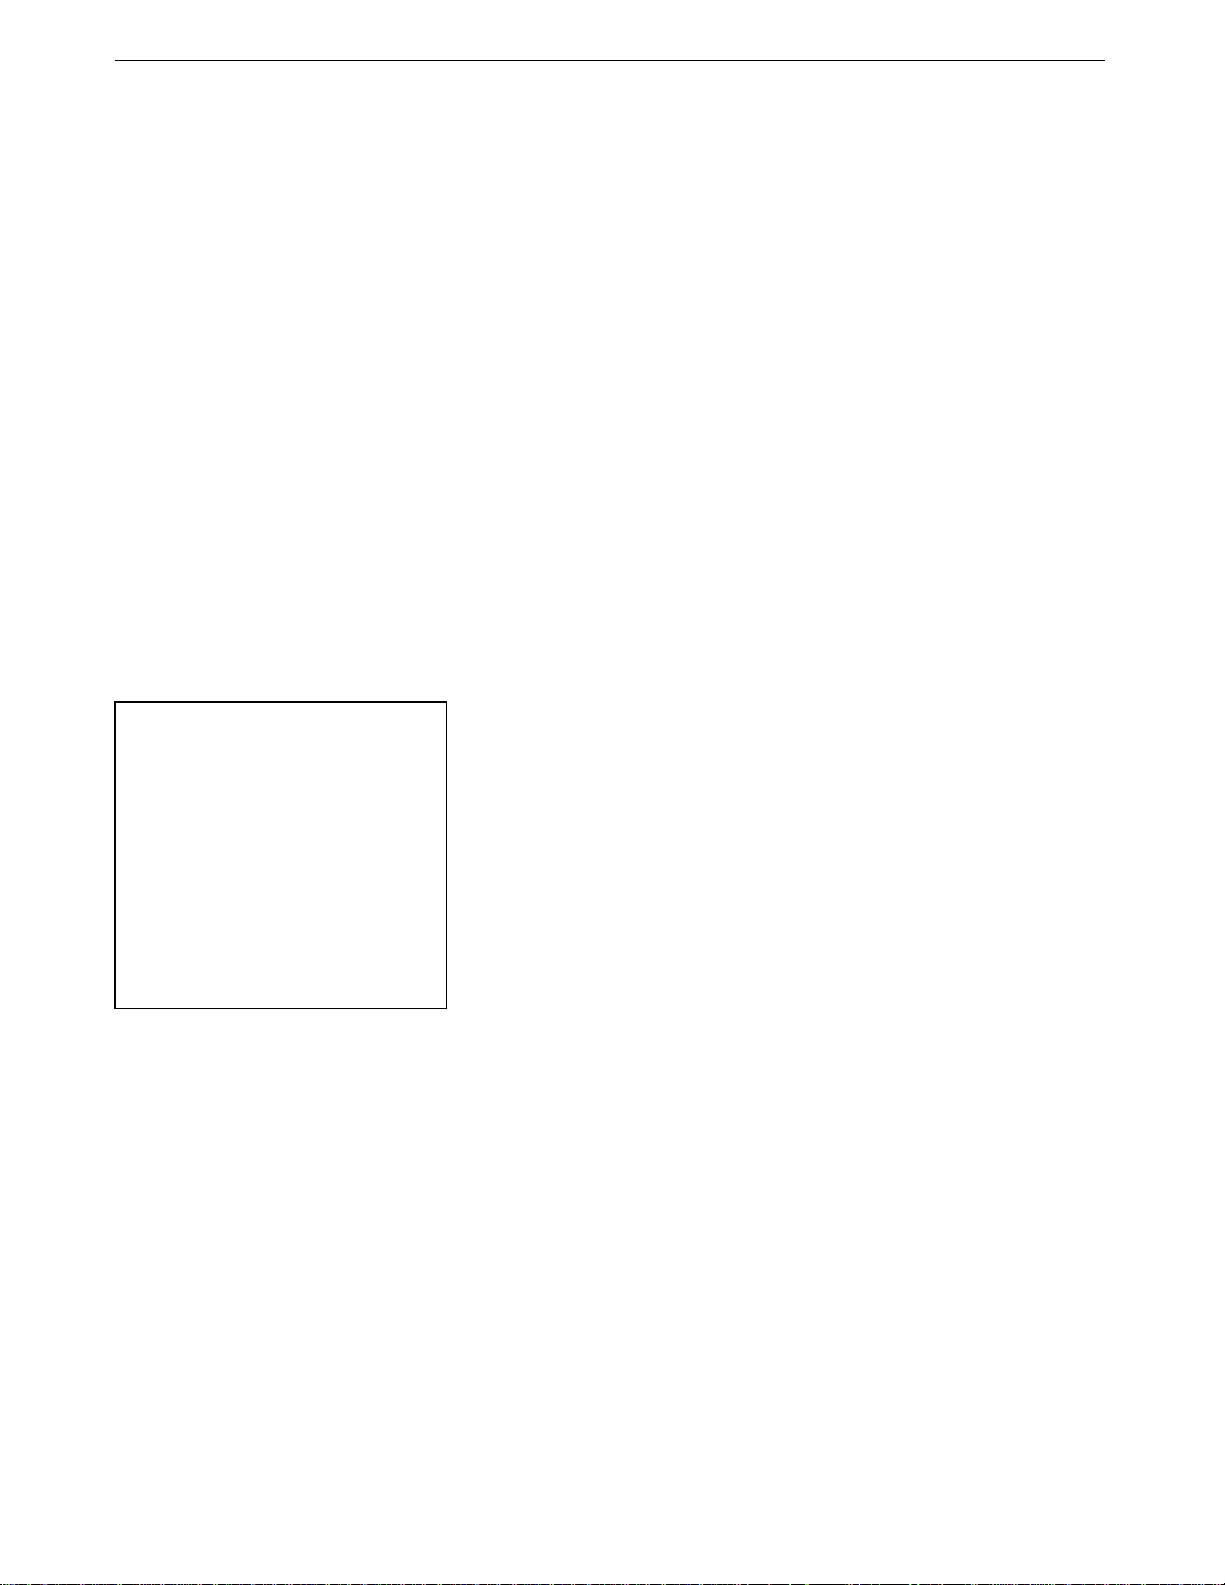
Horizontal Orientation, Downcast Data
The FastCAT is intended for obtaining upcast data, and will not generally give
best quality results on the downcast. If you must have good quality downcast
data, mount the FastCAT horizontally, with the temperature sting at the
bottom, as shown. This orientation provides an upward path from intake to
exhaust, allowing air to leave the system.
33
Page 34
Section 4: Deploying and Operating FastCAT
Positioning Relative to Other Instruments
Position the FastCAT so that other instruments and hardware do not thermally
contaminate the water that flows past the sensors.
Profiling Speed
A profiling speed of approximately 1 meter/second usually provides good
quality data. However, the amount of ship motion, and the dynamic effect it
has on data quality, must be considered as operating conditions change. In
rough seas or other conditions (small boats) where the ship’s dynamic motion
is large, increase the profiling speed to as much as 2 to 3 meters/second to
reduce dynamic errors (spiking) caused by the rapidly changing ascent/descent
rate of the FastCAT (yo-yo effect).
In an unpumped CTD, slow profiling speeds can cause reduced flushing of the
conductivity cell, and salinity spiking can be severe in areas of strong
temperature gradients. Since the FastCAT’s pump creates and maintains a
constant and optimum flow, the FastCAT can be raised slowly to give
greater vertical resolution in the data, especially on lakes or protected bays,
or in other calm conditions. Adjust the ascent rate according to the amount of
ship motion (i.e., sea state). On a very calm lake, 10 cm/second is feasible if
used with a constant winch speed.
Spiking is sometimes seen in the derived values for salinity, density, or sound
Notes:
• The FastCAT performs real-time
alignment of conductivity and
temperature data if
PROCESSREALTIME=Y and
OUTPUTFORMAT=1 or 3.
• See the SBE Data Processing Help
files and/or manual for information
on data processing modules that
can align conductivity and
temperature data, and correct data
for the influences of ship motion
and minimize salinity spiking.
velocity. Spiking results largely from a response time mismatch of the
conductivity and temperature sensors, especially when the profiling rate is
non-uniform. The amount of spiking depends on the temperature gradient, and
is much worse when coupled surface motion causes the instrument to stop -
or even reverse - its descent. In the event of heavy ship motion, it may be
worth letting the instrument free-fall. When very heavy seas cause severe
ship motion and result in periodic reversals of the instrument descent, the
data set can be greatly improved by removing scans taken when the pressure is
not increasing.
Temperature Equilibration
Where the water temperature is very different from the temperature at which
the FastCAT has been stored, better results are obtained if the FastCAT is
allowed to equilibrate to the water temperature at the surface (soak) for several
minutes before beginning the profile. The reason is not that the electronics are
temperature sensitive - they are not - but that the thermal influence of the
instrument housing on the water entering the cell will be reduced. If the
difference between water and storage temperature is extreme, allow more
soak time.
34
Page 35
Section 4: Deploying and Operating FastCAT
Setup for Deployment
Program the FastCAT for the intended deployment using SEATERM
(see Command Descriptions).
Note:
See Acquiring and Processing
Data with SEASAVE and
SBE Data Processing.
Note:
See Acquiring Real-Time Data with
ROV, AUV, etc. for Processing by
Sea-Bird Software.
• SEASAVE, our real-time data acquisition program, generates a data file
with data format and header information that is compatible with our
SBE Data Processing post-processing software. If the FastCAT will be
connected directly to the computer or to an SBE 36 Deck Unit and you
will be using SEASAVE to acquire and view real-time data, you must set
OUTPUTFORMAT=0 (output raw hexadecimal data).
• If the FastCAT will be connected directly to the computer and you will be
using SEATERM to view real-time data, you must press Capture on the
Toolbar to save the data to a .cap file. Note that SEATERM does not
generate a data file that is compatible with SBE Data Processing.
For ease in viewing data, set OUTPUTFORMAT=3 (output decimal
engineering units).
• If the FastCAT will be connected to an ROV, AUV, etc., the vehicle must
include a data logger for the FastCAT data. Typically, this data will not
be in a format that is compatible with SBE Data Processing. However, if
the data logger saves all the FastCAT data (complete time series) to a
verbatim (unaltered) file, preserving the exact data format output by the
FastCAT, the file can be processed with SBE Data Processing, after some
additional file manipulation to add required header information. To
generate a file that you can ultimately use in SBE Data Processing, you
must set OUTPUTFORMAT=3 (output decimal engineering units).
35
Page 36
Section 4: Deploying and Operating FastCAT
Deployment
CAUTION:
Do not use WD-40 or other
petroleum-based lubricants, as they
will damage the connectors.
Locking
sleeve
Cable
Remove cap
from end of
T-C Duct
FastCAT with straight exhaust fitting
1. Install the data I/O cable on the FastCAT end cap:
A. Lightly lubricate the inside of the cable connector with silicone
grease (DC-4 or equivalent).
B. Standard Connector - Install the cable connector, aligning the raised
bump on the side of the cable connector with the large pin (pin 1 ground) on the FastCAT. Remove any trapped air by burping or
gently squeezing the connector near the top and moving your fingers
toward the end cap. OR
MCBH Connector – Install the cable connector, aligning the pins.
C. Place the locking sleeve over the cable connector and tighten it finger
tight only. Do not overtighten the locking sleeve and do not use a
wrench or pliers.
2. Connect the I/O cable to the computer/controller.
3. Connect the I/O cable connector’s red (+) and black (-) wires to a power
supply (9-24 VDC).
4. Verify that the hardware and external fittings are secure.
5. If caps were placed on the end of the T-C Duct and exhaust tee to
keep dust, debris, etc. out of the conductivity cell during storage,
remove the caps.
Remove caps
from both
ends of
exhaust tee
Remove
cap
from
end of
exhaust
Remove cap from
end of T-C Duct
FastCAT with tee exhaust fitting
6. Immediately prior to deployment, apply power and start sampling:
• If AUTORUN=Y, applying power started FastCAT sampling.
• If AUTORUN=N, send START (in SEATERM).
36
Page 37
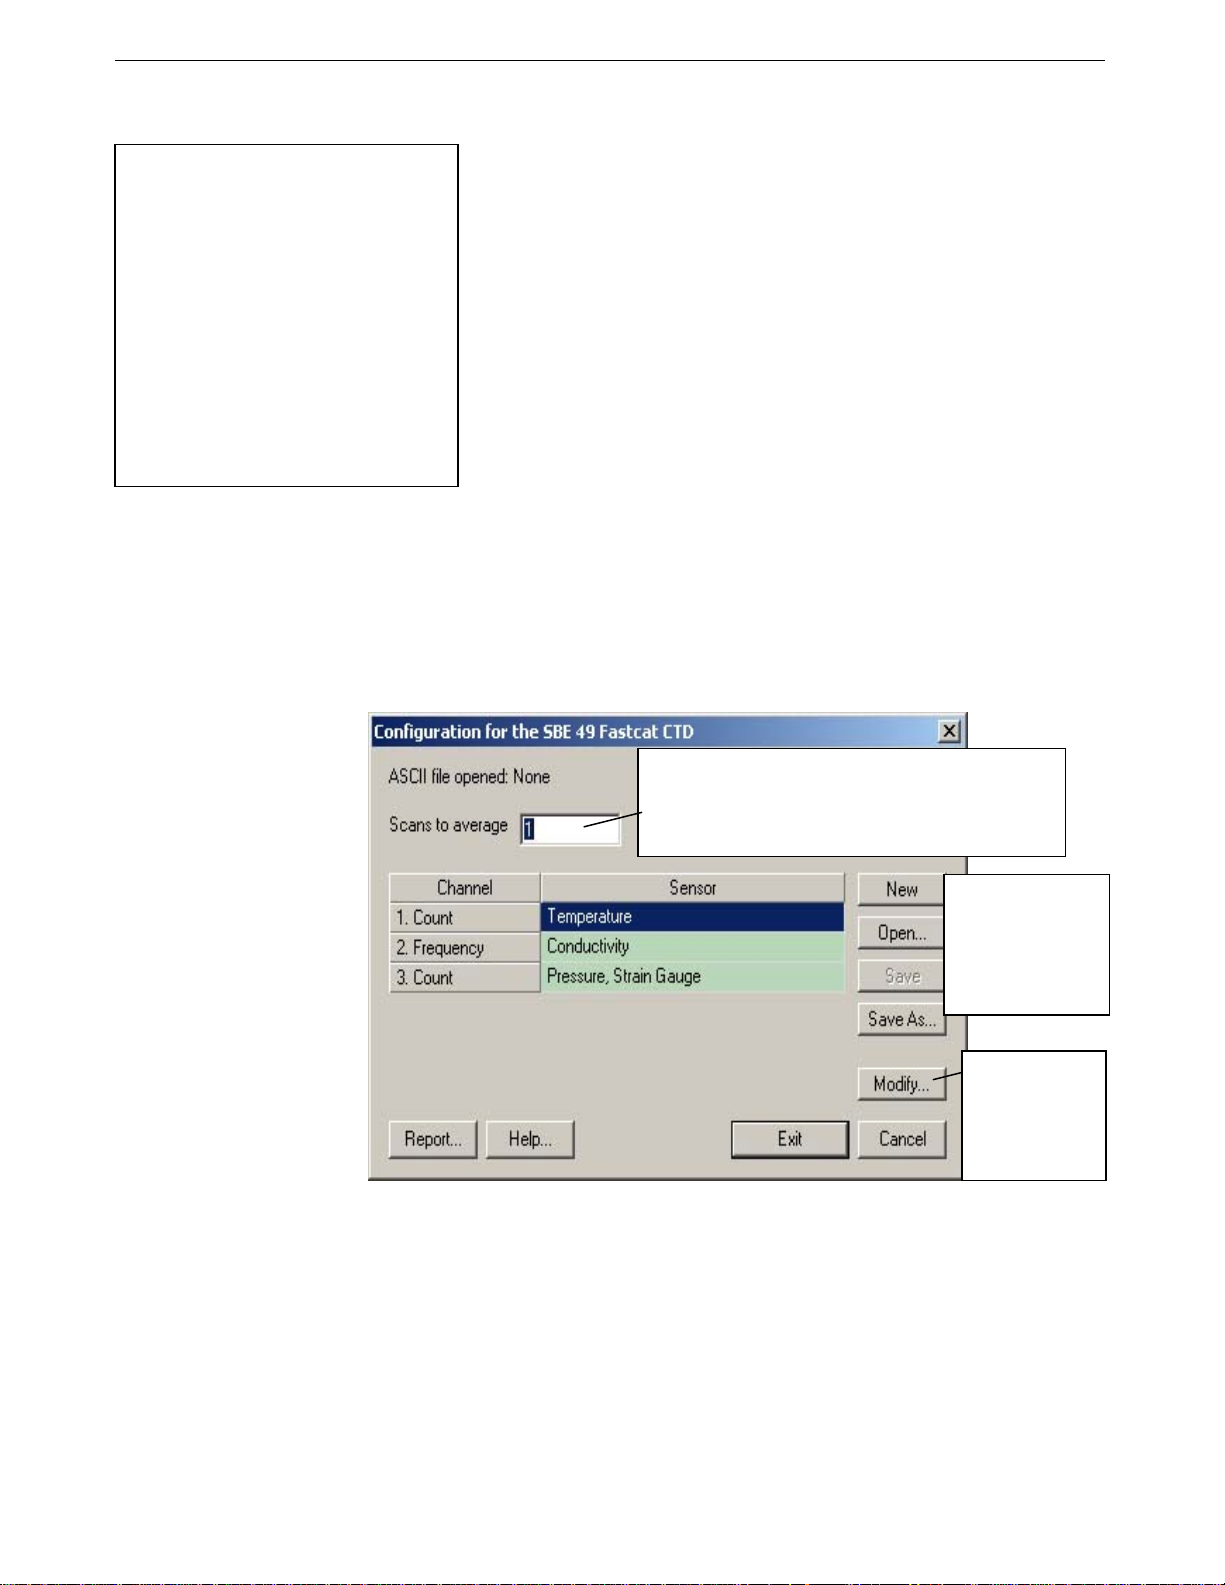
Section 4: Deploying and Operating FastCAT
Acquiring and Processing Data with SEASAVE and SBE Data Processing
Notes:
• When we ship a new instrument, we
include a .con file that reflects the
current instrument configuration as
we know it. The .con file is named
with the instrument serial number,
followed with the .con extension. For
example, for an instrument with
serial number 2375, we name the
.con file 2375.con. You may rename
the .con file if desired; this will not
affect the results.
• The .con file can be viewed and
modified in SEASAVE or in
SBE Data Processing.
Verifying Contents of .con File
SEASAVE, our real-time data acquisition and display program, and SBE Data
Processing, our data processing software, require a .con file. The .con file
defines the instrument – data output rate, and serial numbers, calibration dates,
and calibration coefficients for the sensors (conductivity, temperature, and
pressure). SEASAVE and SBE Data Processing use the information in the .con
file to interpret and process the raw data. If the .con file does not match the
actual instrument configuration, the software will not be able to interpret
and process data correctly.
Review the .con file:
1. Double click on Seasave.exe.
2. In the Configure menu, select New Style Instrument Configuration / Select
Instrument Configuration. In the dialog box, select the appropriate .con
file and click Open.
3. In the Configure menu, select New Style Instrument Configuration /
Modify Selected Instrument Configuration. The configuration dialog box
appears. Verify that the calibration coefficients for all the sensors are
up-to-date.
Number of samples to average per scan. FastCAT
samples at 16 Hz (0.0625 seconds), averages data, and
transmits averaged data real-time. Must agree with number
programmed into FastCAT with NAVG=; see reply from
status command (DS).
New to create new
.con file for this CTD.
Open to select
different .con file.
Save or Save As to
save current .con file
settings.
Click a sensor and
click Modify to
view or change
calibration
coefficients for that
sensor.
4. Click Save or Save As to save any changes to the .con file. Click Exit
when done reviewing / modifying the .con file.
37
Page 38
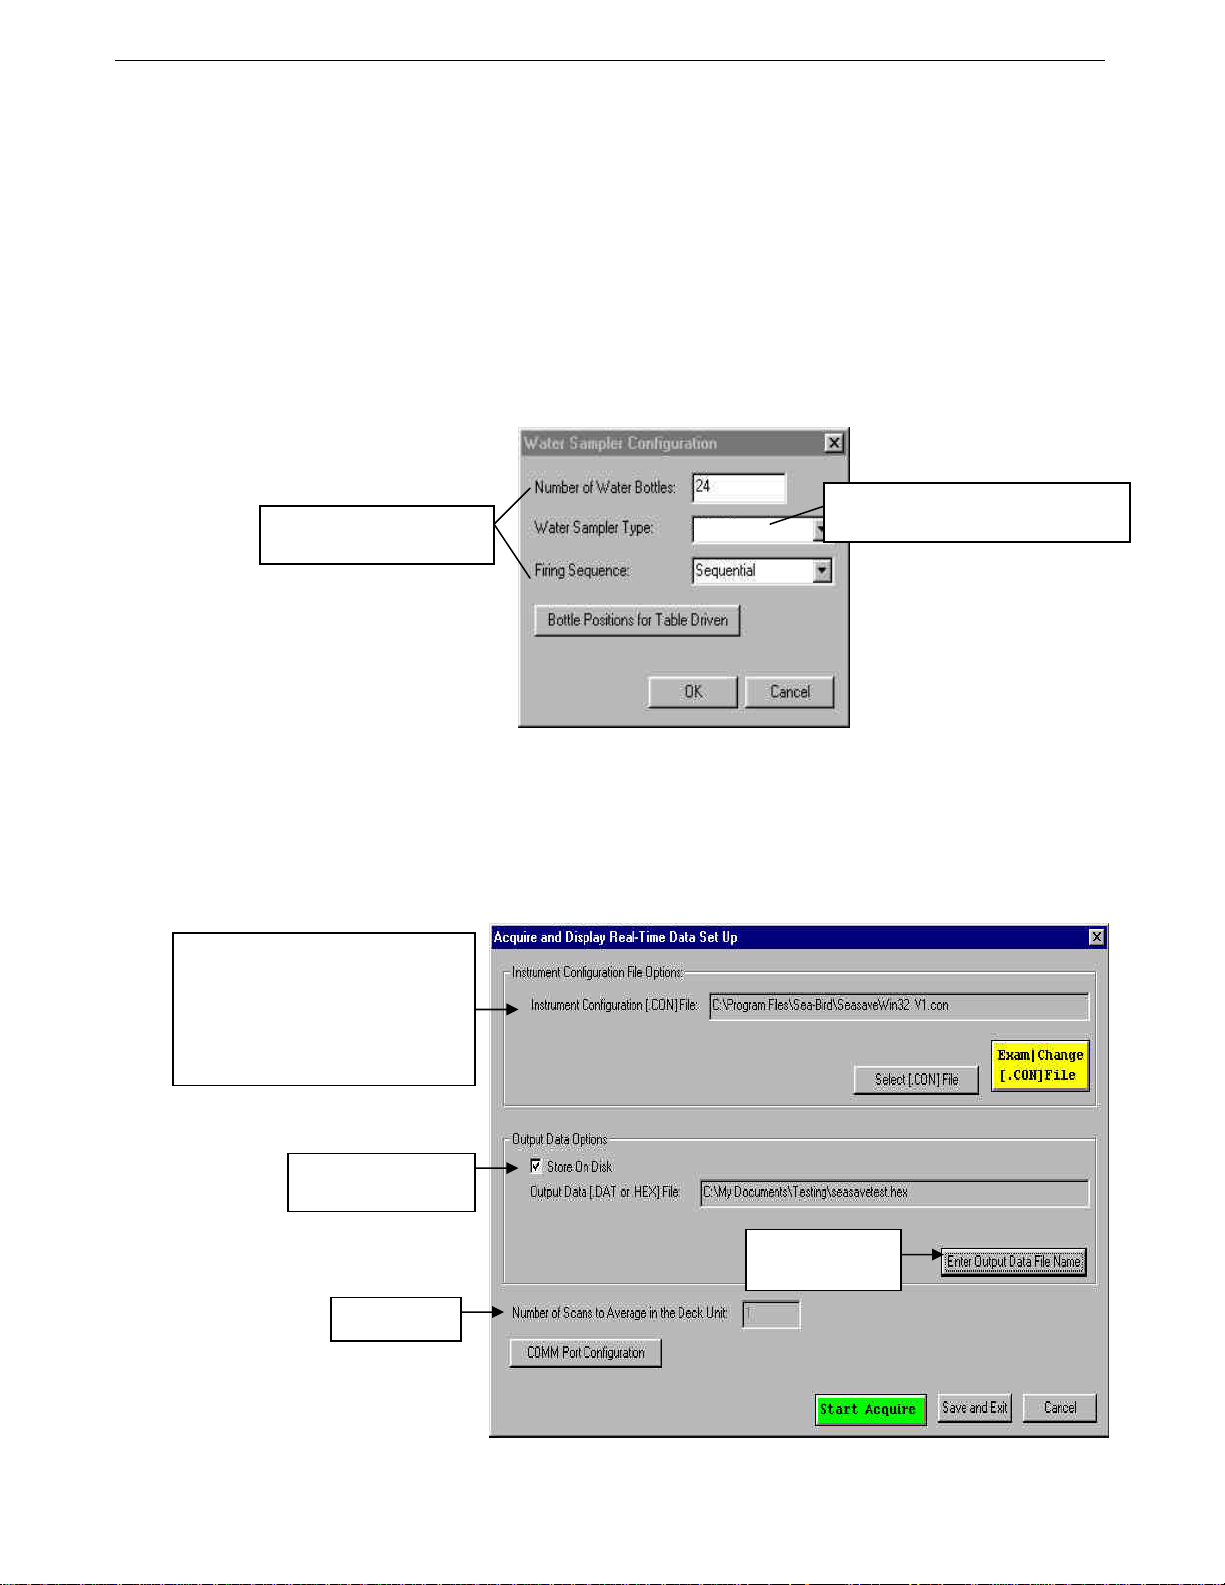
Section 4: Deploying and Operating FastCAT
Acquiring Real-Time Data with SEASAVE
1. Start FastCAT sampling:
• If AUTORUN=Y: Turn on power. FastCAT will start sampling and
transmitting data to the computer. Note that the data will not appear
in SEASAVE until you tell SEASAVE to start real-time data
acquisition below.
• If AUTORUN=N: Turn on power. Run SEATERM, command the
FastCAT to start sampling (START), click SEATERM’s Disconnect
button, and then close SEATERM.
2. Double click on Seasave.exe.
3. In the Configure menu, select Water Sampler Configuration. The dialog
box looks like this:
None is only valid selection for a
Not applicable (selection
does not affect operation).
None
system using FastCAT.
Select None for water sampler type, and click OK.
4. Perform any other desired setup in the Configure and
ScreenDisplay menus.
5. In the RealTime Data menu, select Start Acquisition. The dialog box looks
like this:
Configuration file defines data output
rate and serial numbers, calibration
dates, and calibration coefficients for
sensors (conductivity, temperature, and
pressure). Verify that .con file matches
your instrument setup. See Verifying
Contents of .con File above.
Select to save real-time
data to a file.
Click to select file
location and name.
Not applicable.
38
Page 39
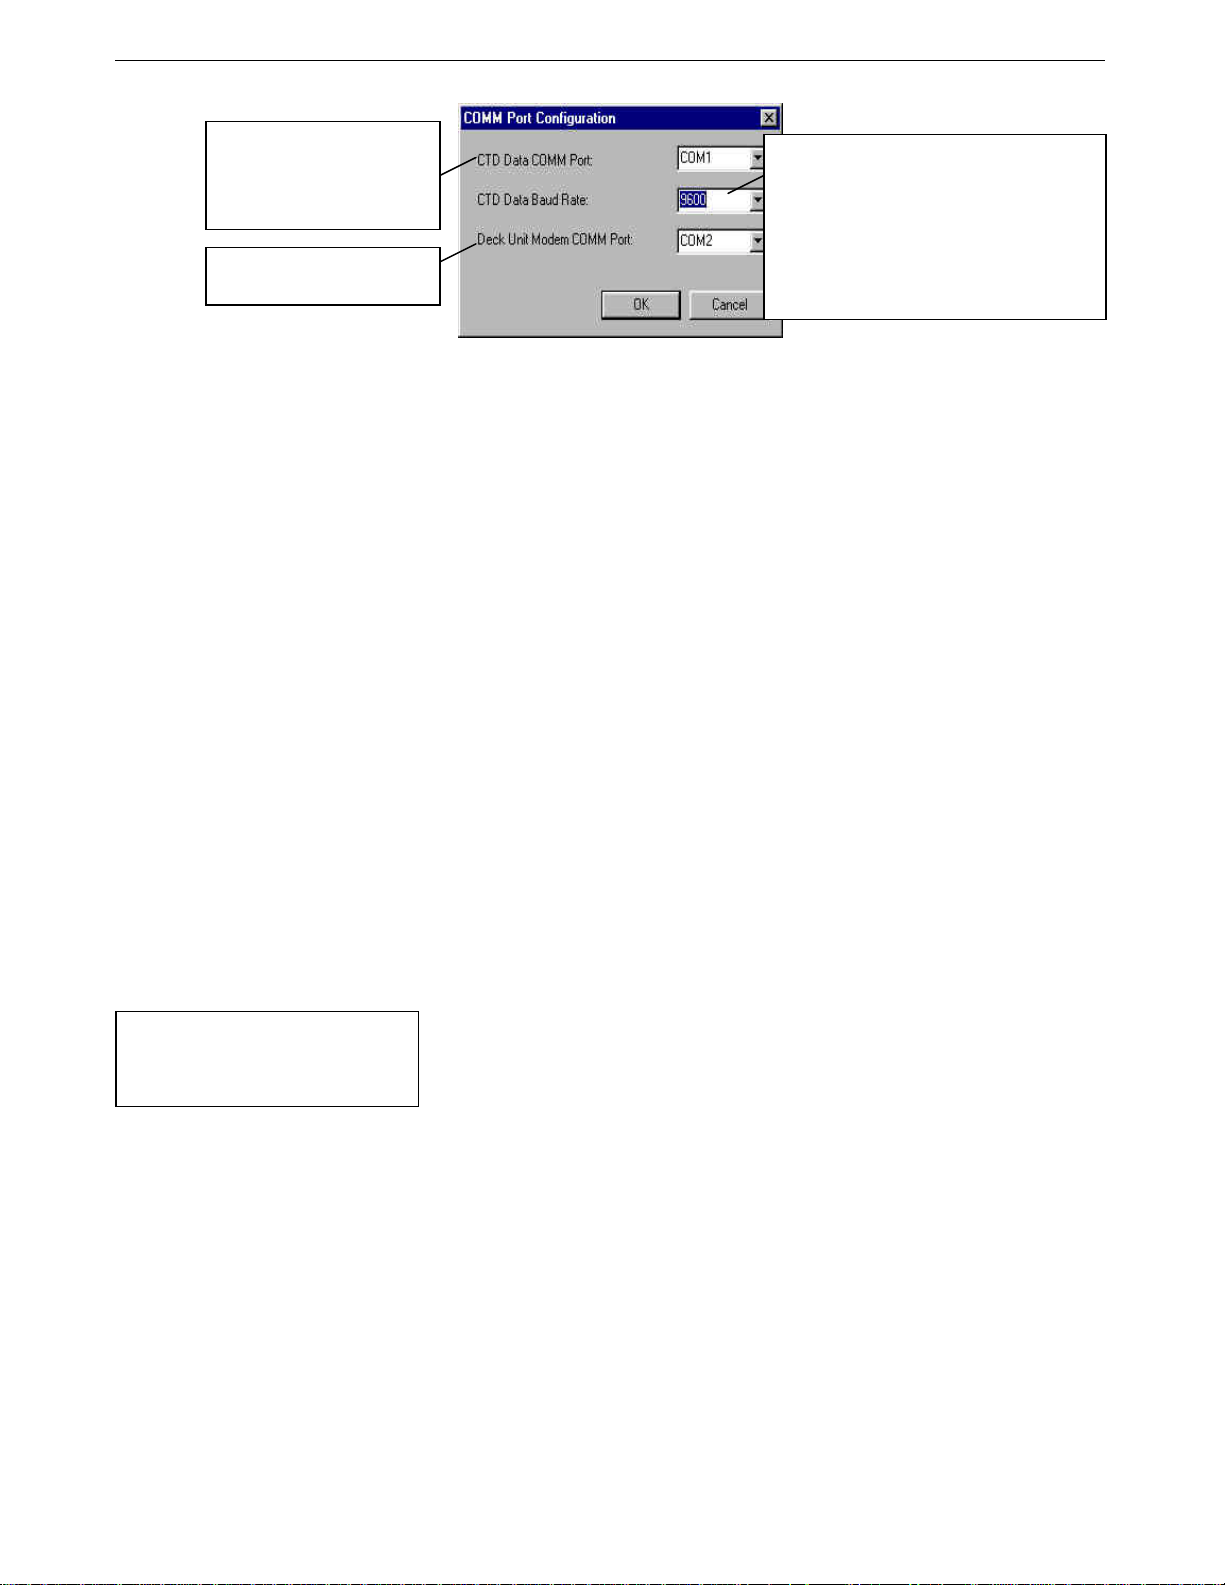
Section 4: Deploying and Operating FastCAT
6. Click COMM Port Configuration. The dialog box looks like this:
Computer port connected to:
• FastCAT, OR
• SBE 36 Deck Unit Serial
Data connector
Not applicable (selection
does not affect operation).
Note:
See the SBE Data Processing
manual and/or Help files.
Baud rate for communication:
• Between FastCAT and computer (if
FastCAT connected directly to computer)
- must match baud set in FastCAT with
BAUD=, OR
• Between SBE 36 Deck Unit and
computer (if FastCAT connected to Deck
Unit) – must match SBE 36 dip switch
setting (9600 or 19200).
Make the desired selections and click OK.
7. In the Acquire and Display Real Time Data Set Up dialog box, click
Start Acquire.
A. If SEASAVE was set up to prompt for header information (Configure
menu / Header Form), the Header Information dialog box appears.
Fill in the desired information to be added to the data file header, and
click OK.
B. SEASAVE prompts Waiting for data. Data then starts appearing in the
screen display(s). SEASAVE will time out if data is not received from
the FastCAT within 60 seconds.
8. When done acquiring data, in the RealTime Data menu, select
Stop Acquisition.
9. Close SEASAVE.
10. Stop sampling:
• If AUTORUN=Y: Remove external power.
• If AUTORUN=N: Send STOP in SEATERM.
Processing Data with SBE Data Processing
1. In SBE Data Processing’s File menu, select Data Conversion to convert
the raw hex (.hex) data file to engineering units (.cnv file).
• Data Conversion and some other processing modules require the
instrument configuration (.con) file for input. See Verifying Contents
of .con File above for a description of the .con file, which is used in
both SEASAVE and in SBE Data Processing.
2. The .cnv file can be further processed and plotted in SBE Data
Processing’s other modules.
39
Page 40
Section 4: Deploying and Operating FastCAT
Acquiring Real-Time Data with ROV, AUV, etc. for Processing by Sea-Bird Software
Note:
You can perform additional processing
in SBE Data Processing even if you
already aligned, filtered, and corrected
for cell thermal mass using the
FastCAT’s real-time data processing
capability (PROCESSREALTIME=Y).
For example, you may want to remove
loops caused by pressure reversals
(ship heave), derive additional
parameters such as density, bin
average the data, or plot the data.
Note
If OUTPUTSAL=N and
OUTPUTSV=Y, select
sound velocity for column 4.
Sea-Bird’s SBE Data Processing post-processing software typically converts a
FastCAT .hex file from SEASAVE to a .cnv file, and then uses the .cnv file in
all additional processing steps. A method to obtain data in the appropriate
format for SBE Data Processing, when data is logged to an ROV, AUV, etc.
instead of acquired with SEASAVE, is presented below. This method requires
an ROV, AUV, etc. to save all the FastCAT data (complete time series)
to a verbatim (unaltered) file, preserving the exact data format output by
the FastCAT:
1. Verify that the FastCAT is set to OUTPUTFORMAT=3
(output decimal engineering units) and AUTORUN=Y (begin sampling
when power is applied).
2. Begin sampling (turn on power to FastCAT).
3. Stop sampling (turn off power to FastCAT).
4. Recover the FastCAT data file from the ROV, AUV, etc.
5. Open the data file with a text editor (such as Wordpad, Notepad, or
Word). Delete any command lines (lines with S> prompt on them)
and any lines with partial scans. Save the file as a text (.txt) file and
close the file.
6. Rename the .txt file with a .asc extension (for example, test.rov was saved
as test.txt, and then renamed as test.asc).
7. In SBE Data Processing’s File menu, select ASCII In. Select the .asc file
as the input file, and enter the desired output (.cnv) file name. On the
Data Setup tab, enter the scan interval (0.0625 seconds for 16 Hz data,
0.125 seconds for 8 Hz data, etc.). Click Select Column Names,
and select:
A. Column 1 - Temperature [ITS-90, deg C]
B. Column 2 - Conductivity [S/m]
C. Column 3 - Pressure, Strain Gauge [db]
D. Column 4 - Salinity [psu]
E. Column 5 - Sound Velocity [Chen-Millero, m/s]
(if OUTPUTSAL=Y)
(if OUTPUTSV=Y)
Click Start Process. ASCII In will create a .cnv file from the input .asc file
and the information on the Data Setup tab.
8. Use other modules in SBE Data Processing to further process and plot the
.cnv file as desired. Note that some processing modules require the
instrument configuration (.con) file as well as the data file for input. See
Verifying Contents of .con File in Acquiring and Processing Data with
SEASAVE and SBE Data Processing above for a description of the .con
file, which is used in both SEASAVE and SBE Data Processing.
40
Page 41
Section 4: Deploying and Operating FastCAT
Recovery
WARNING!
Pressure housings may flood
under pressure due to dirty or
damaged o-rings, or other failed
seals, causing highly compressed
air to be trapped inside. If this
happens, a potentially lifethreatening explosion can occur
when the instrument is brought to
the surface.
If the FastCAT is unresponsive to
commands or shows other signs
of flooding or damage, carefully
secure the instrument in a
location away from people until it
has been determined that
abnormal internal pressure does
not exist.
Contact Sea-Bird for assistance
with procedures for safely
relieving internal pressure.
Rinse the conductivity cell with fresh water. (See Section 5: Routine
Maintenance and Calibration for cell cleaning and storage.)
• Place Tygon tubing over the end of the T-C Duct. Pour the water
through the Tygon, conductivity cell, and exhaust tubing with a syring e
or wash bottle.
41
Page 42
Section 5: Routine Maintenance and Calibration
Section 5:
Routine Maintenance and Calibration
This section reviews corrosion precautions, connector mating and
maintenance, conductivity cell storage and cleaning, pressure sensor
maintenance, replacing optional AF24173 Anti-Foulant Devices, and sensor
calibration. The accuracy of the FastCAT is sustained by the care and
calibration of the sensors and by establishing proper handling practices.
Corrosion Precautions
Rinse the FastCAT with fresh water after use and prior to storage.
All exposed metal is titanium. No corrosion precautions are required, but
direct electrical connection of the titanium to dissimilar metal hardware should
be avoided.
Connector Mating and Maintenance
A mated connector does not require periodic disassembly or other attention.
Inspect a connector that is unmated for signs of corrosion product around the
pins. When remating:
CAUTION:
Do not use WD-40 or other
petroleum-based
lubricants, as they will
damage the connectors.
1. Lightly lubricate the inside of the dummy plug/cable connector with
silicone grease (DC-4 or equivalent).
2. Standard Connector - Install the plug/cable connector, aligning the
raised bump on the side of the plug/cable connector with the large pin
(pin 1 - ground) on the FastCAT. Remove any trapped air by burping or
gently squeezing the plug/connector near the top and moving your fingers
toward the end cap. OR
MCBH Connector – Install the plug/cable connector, aligning the pins.
3. Place the locking sleeve over the plug/cable connector. Tighten the
locking sleeve finger tight only. Do not overtighten the locking sleeve
and do not use a wrench or pliers.
Verify that a cable or dummy plug is installed before deployment.
42
Page 43
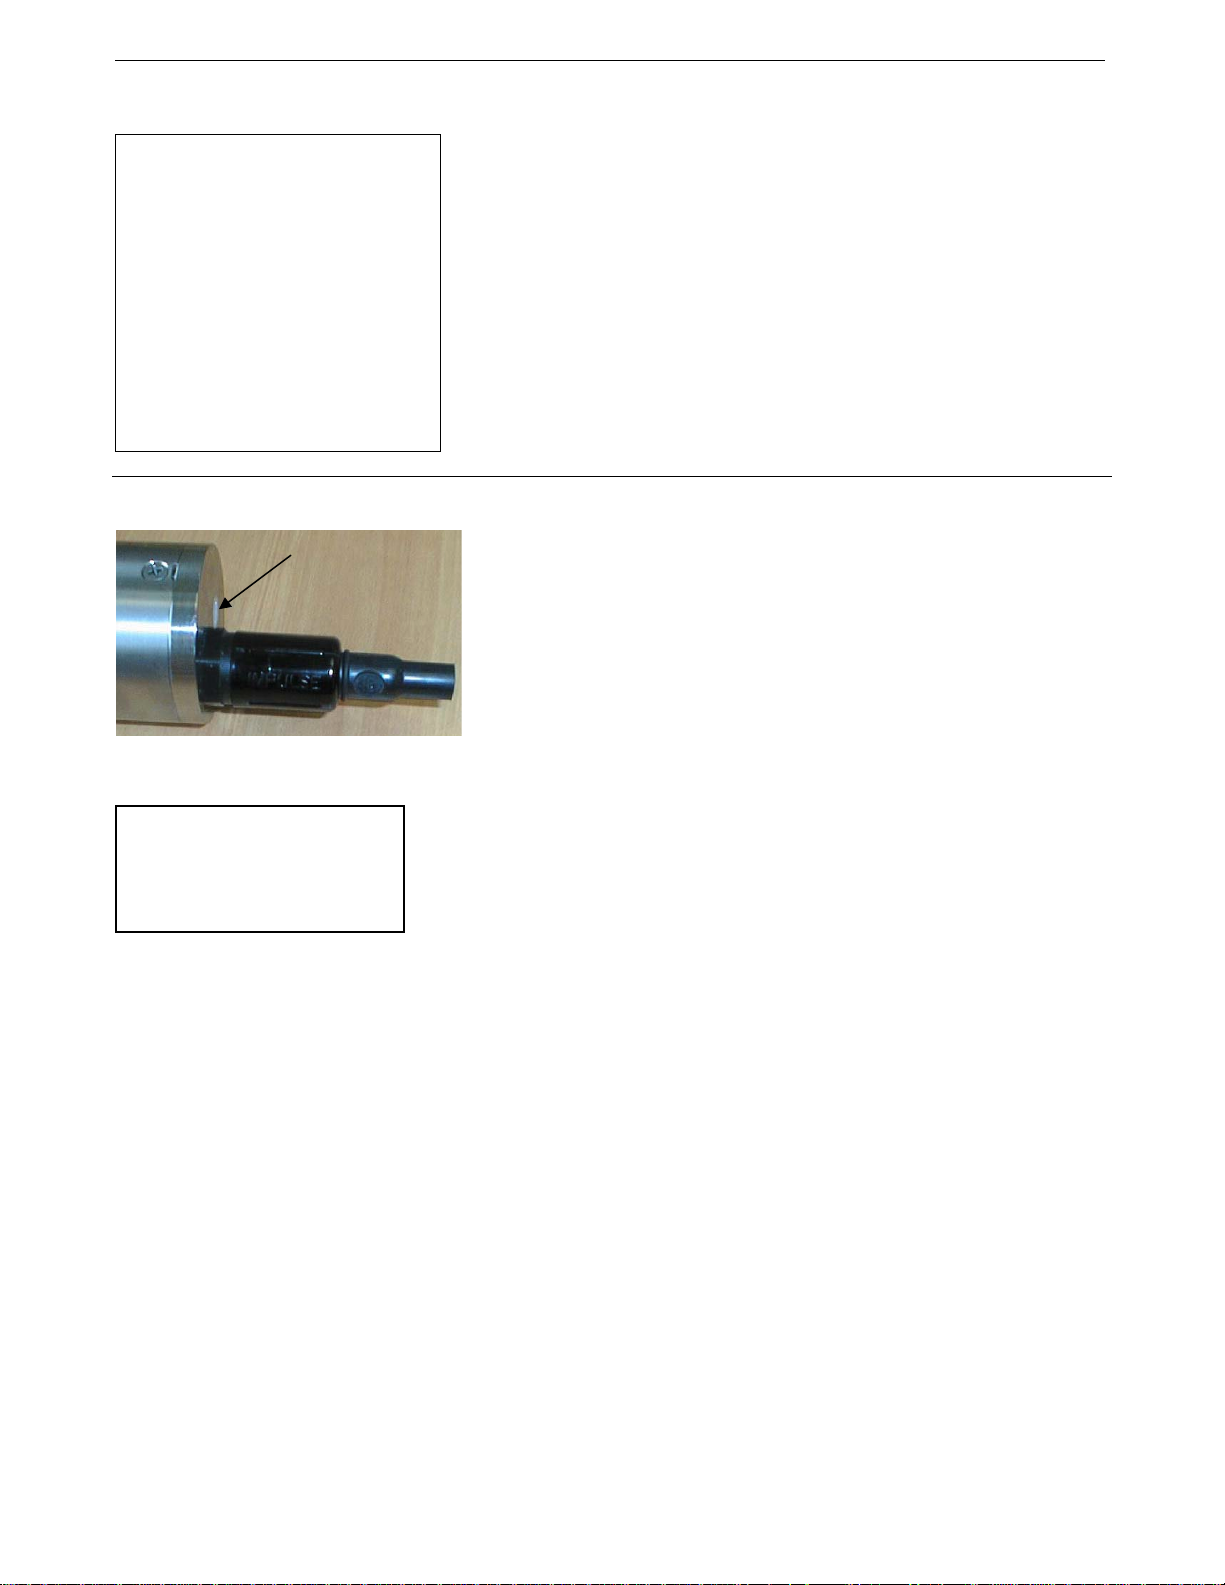
Section 5: Routine Maintenance and Calibration
Conductivity Cell Maintenance
CAUTIONS:
• Do not put a brush or any object
inside the conductivity cell to
dry it or clean it. Touching and
bending the electrodes can
change the calibration. Large
bends and movement of the
electrodes can damage the cell.
• Do not store the FastCAT with
water in the conductivity cell.
Freezing temperatures (for
example, in Arctic environments or
during air shipment) can break the
cell if it is full of water.
The FastCAT’s conductivity cell is shipped dry to prevent freezing
in shipping. Refer to Application Note 2D: Instructions for Care and
Cleaning of Conductivity Cells for conductivity cell cleaning procedures
and cleaning materials.
Pressure Sensor Maintenance
Pressure sensor
port plug
CAUTION:
Do not put a brush or any
object in the pressure port.
Doing so may damage or break
the pressure sensor.
At the factory, the pressure sensor and pressure port were filled with a silicon
oil, and a pressure port plug was used to retain the oil. The oil transmits
hydrostatic pressure to the pressure sensor inside the instrument. Because of
the viscosity of the silicone oil, the oil does not run out of the pressure sensor
port plug. However, due to temperature and pressure cycling over long
periods, it is normal for some oil to slowly leak out of the plug. It is not
necessary to refill the oil.
Periodically (approximately once a year) inspect the pressure port to remove
any particles, debris, etc:
1. Unscrew the pressure port plug from the pressure port. The fitting may
contain silicon oil from the factory, so there may be some spillage.
2. Rinse the pressure port with warm, de-ionized water to remove any
particles, debris, etc.
3. Replace the pressure port plug.
43
Page 44
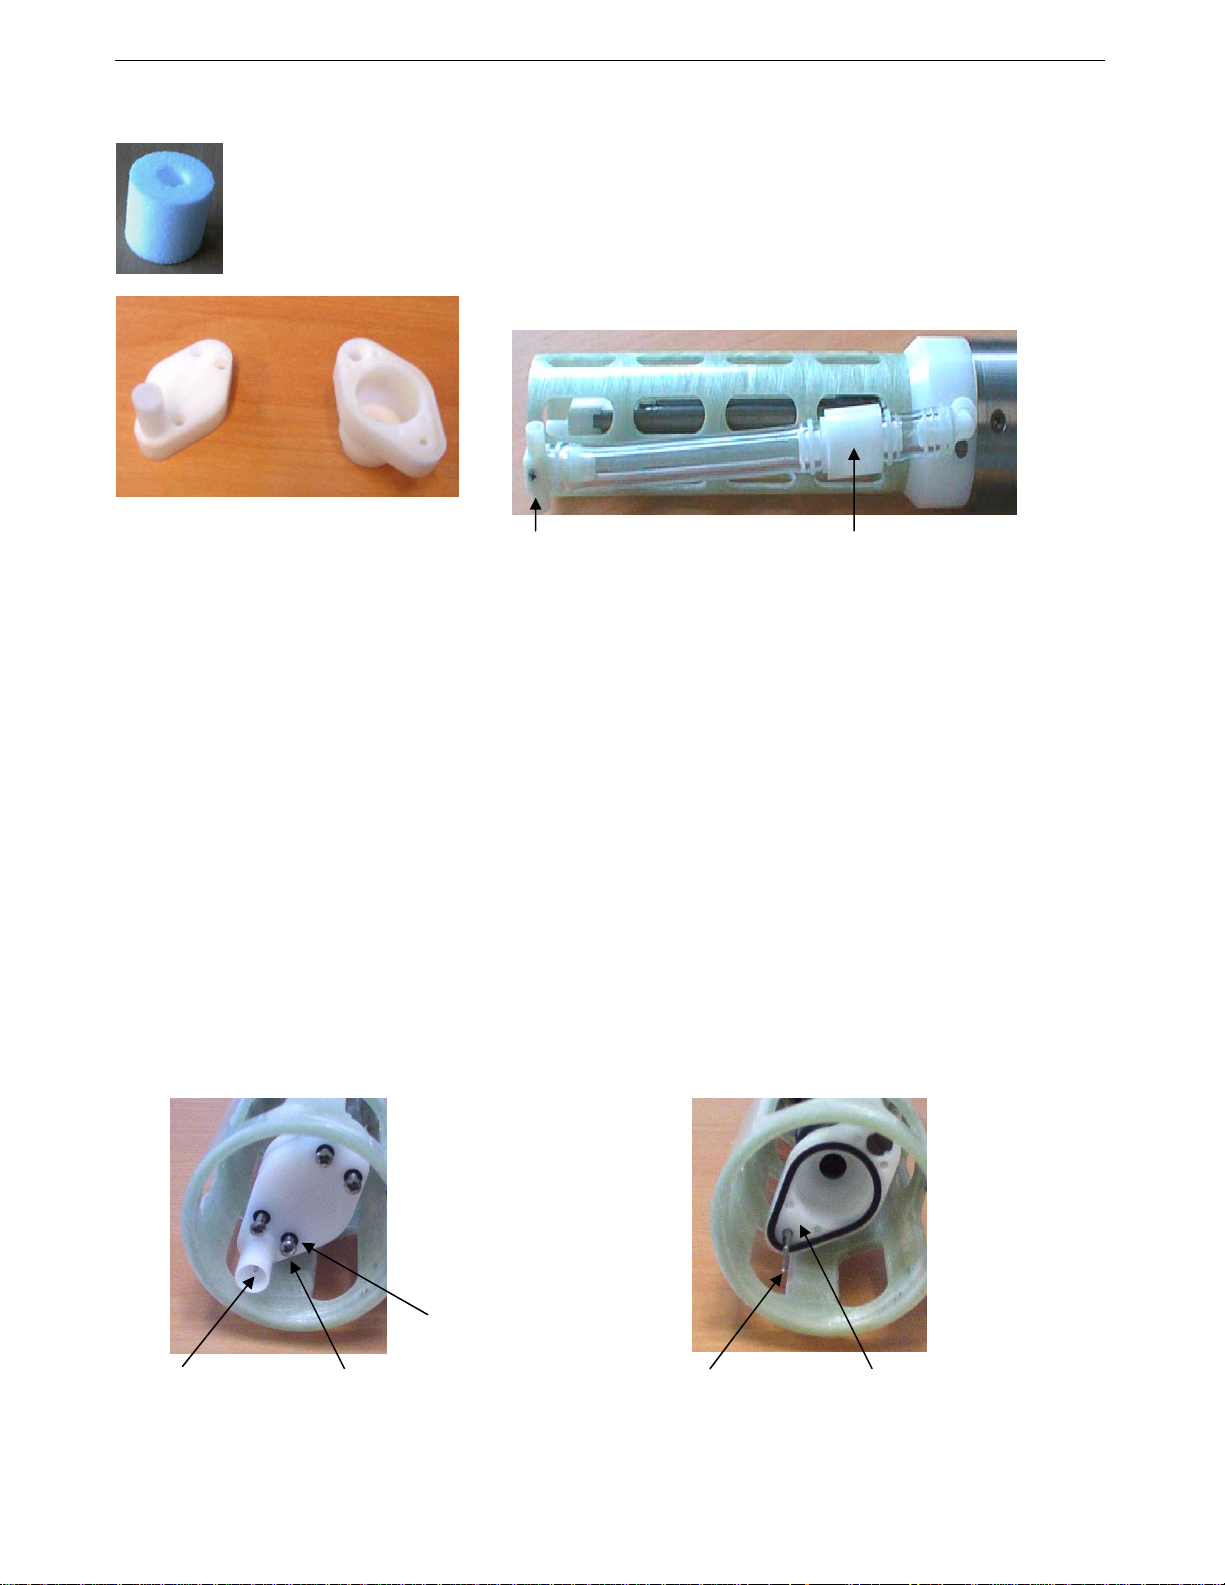
Section 5: Routine Maintenance and Calibration
p
Replacing Optional Anti-Foulant Devices – Mechanical Design Change
The standard T-C Duct also serves as the anti-foulant device intake fitting. In
Dummy Anti-Foulant
Device for
intake fitting
Top Base
T-C Duct / Anti-
foulant device intake
& base (standard)
to
the standard configuration (no anti-foulant devices), the intake fitting is
shipped with a dummy anti-foulant device (inert plastic) installed to
reduce turbulence in the T-C Duct.
As an option for moored applications, the FastCAT is supplied with an exhaust
anti-foulant device fitting and AF24173 Anti-Foulant Devices.
Exhaust tee shown; anti-foulant
device fitting detail also applies to
FastCAT with straight exhaust.
Anti-foulant device exhaust
cup & cap (optional)
The following two pages provide details on repl aci ng the Ant i -F oul ant
Devices. However, due to a change in the mechanical design of the T-C Duct
assembly, Steps 1 – 4 and 7 – 9 in Anti-Foulant Device in T-C Duct Assembly
are no longer applicable. See the revised details below:
Removing T-C Duct Top (replaces Steps 1 – 4)
A. Remove the four small Phillips-head screws with o-rings securing the T-C
Duct top to the T-C Duct base.
B. Carefully pull the T-C Duct top straight out – do not apply any sideways
motion or you may damage the temperature sting.
Replacing T-C Duct Top (replaces Steps 7 – 9)
C. Carefully replace the T-C Duct top on the base, reinstalling the four small
Phillips-head screws and o-rings.
O-rings (4)
Temperature sting
Phillips-head screws (4),
shown partially removed
Temperature
sting
T-C Duct Base remains attached
and sealed to top of conductivity
cell - do not remove
44
Page 45
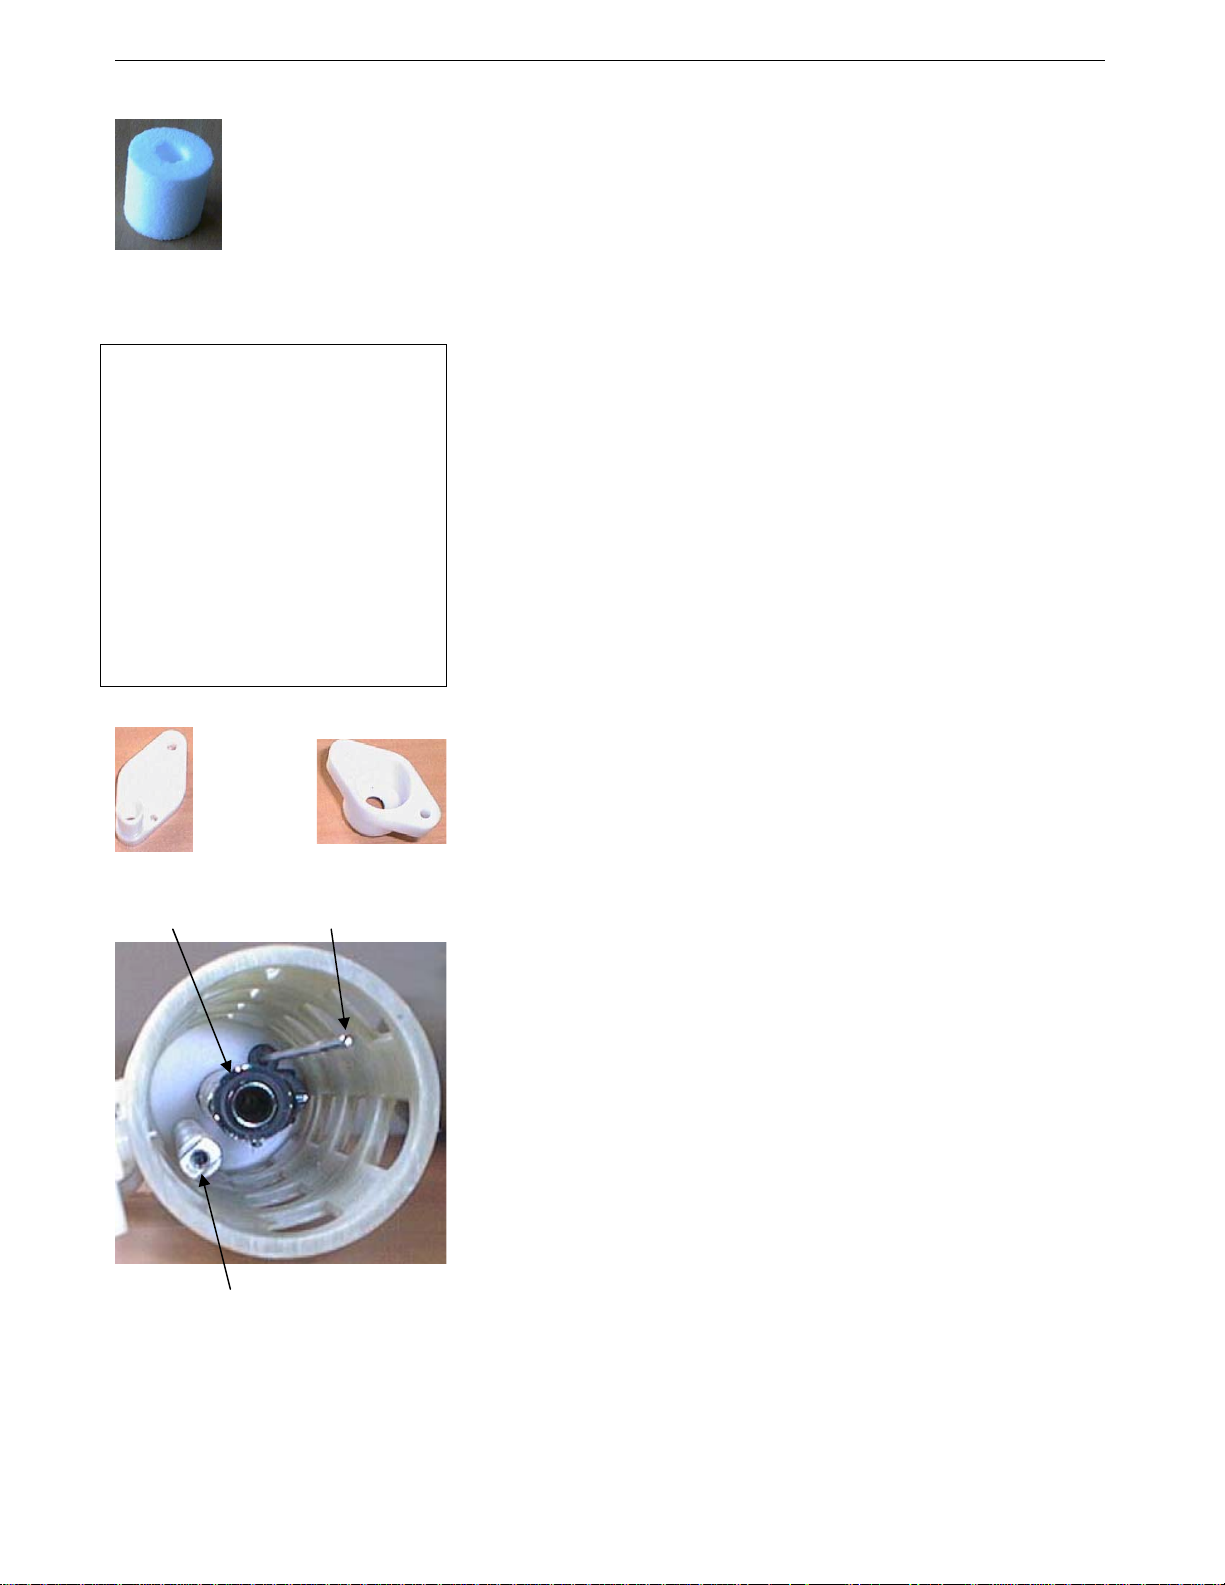
Section 5: Routine Maintenance and Calibration
Replacing Optional Anti-Foulant Devices (SBE 49)
As an option, the FastCAT is supplied with anti-foulant device fittings and
AF24173
Anti-Foulant
Device
WARNING!
AF24173 Anti-Foulant Devices
contain bis(tributyltin) oxide. Handle
the devices only with rubber or latex
gloves. Wear eye protection. Wash
with soap and water after handling.
Read precautionary information on
product label (see Appendix IV)
before proceeding.
It is a violation of US Federal Law to
use this product in a manner
inconsistent with its labeling.
T-C Duct
Top Base
Conductivity
cell
Temperature
sting
Anti-Foulant Devices. The Anti-Foulant Devices are installed:
• in the T-C Duct assembly;
• in the anti-foulant device cup and cap (part of the external pump exhaust
tubing).
Wearing rubber or latex gloves, follow this procedure to replace each AntiFoulant Device (two):
Anti-Foulant Device in T-C Duct Assembly
1. Remove the large screw securing the T-C Duct to the mast.
2. Gently pull the T-C Duct straight out - you will feel some resistance as the
seals disengage. Do not twist the T-C Duct or apply an y si dew ays
motion, or you may damage the conductivity cell.
3. Remove the two small Phillips-head screws securing the T-C Duct top to
the T-C Duct base.
4. Pull the T-C Duct top off of the base.
5. Remove the old Anti-Foulant Device. If the old device is difficult to
remove, use needle-nose pliers and carefully break up material.
6. Place the new Anti-Foulant Device in the T-C Duct base.
7. Replace the T-C Duct top on the base, reinstalling the two small Phillips-
head screws.
8. Carefully slide the T-C Duct assembly over the temperature sting,
aligning the large screw hole with the screw hole in the mast. Push the
assembly onto the end of the conductivity cell - you will feel some
resistance as the seals engage. Do not twist the T-C Duct or apply any
sideways motion, or you may damage the conductivity cell.
9. Reinstall the large screw to secure the assembly to the mast.
Mast
45
Page 46
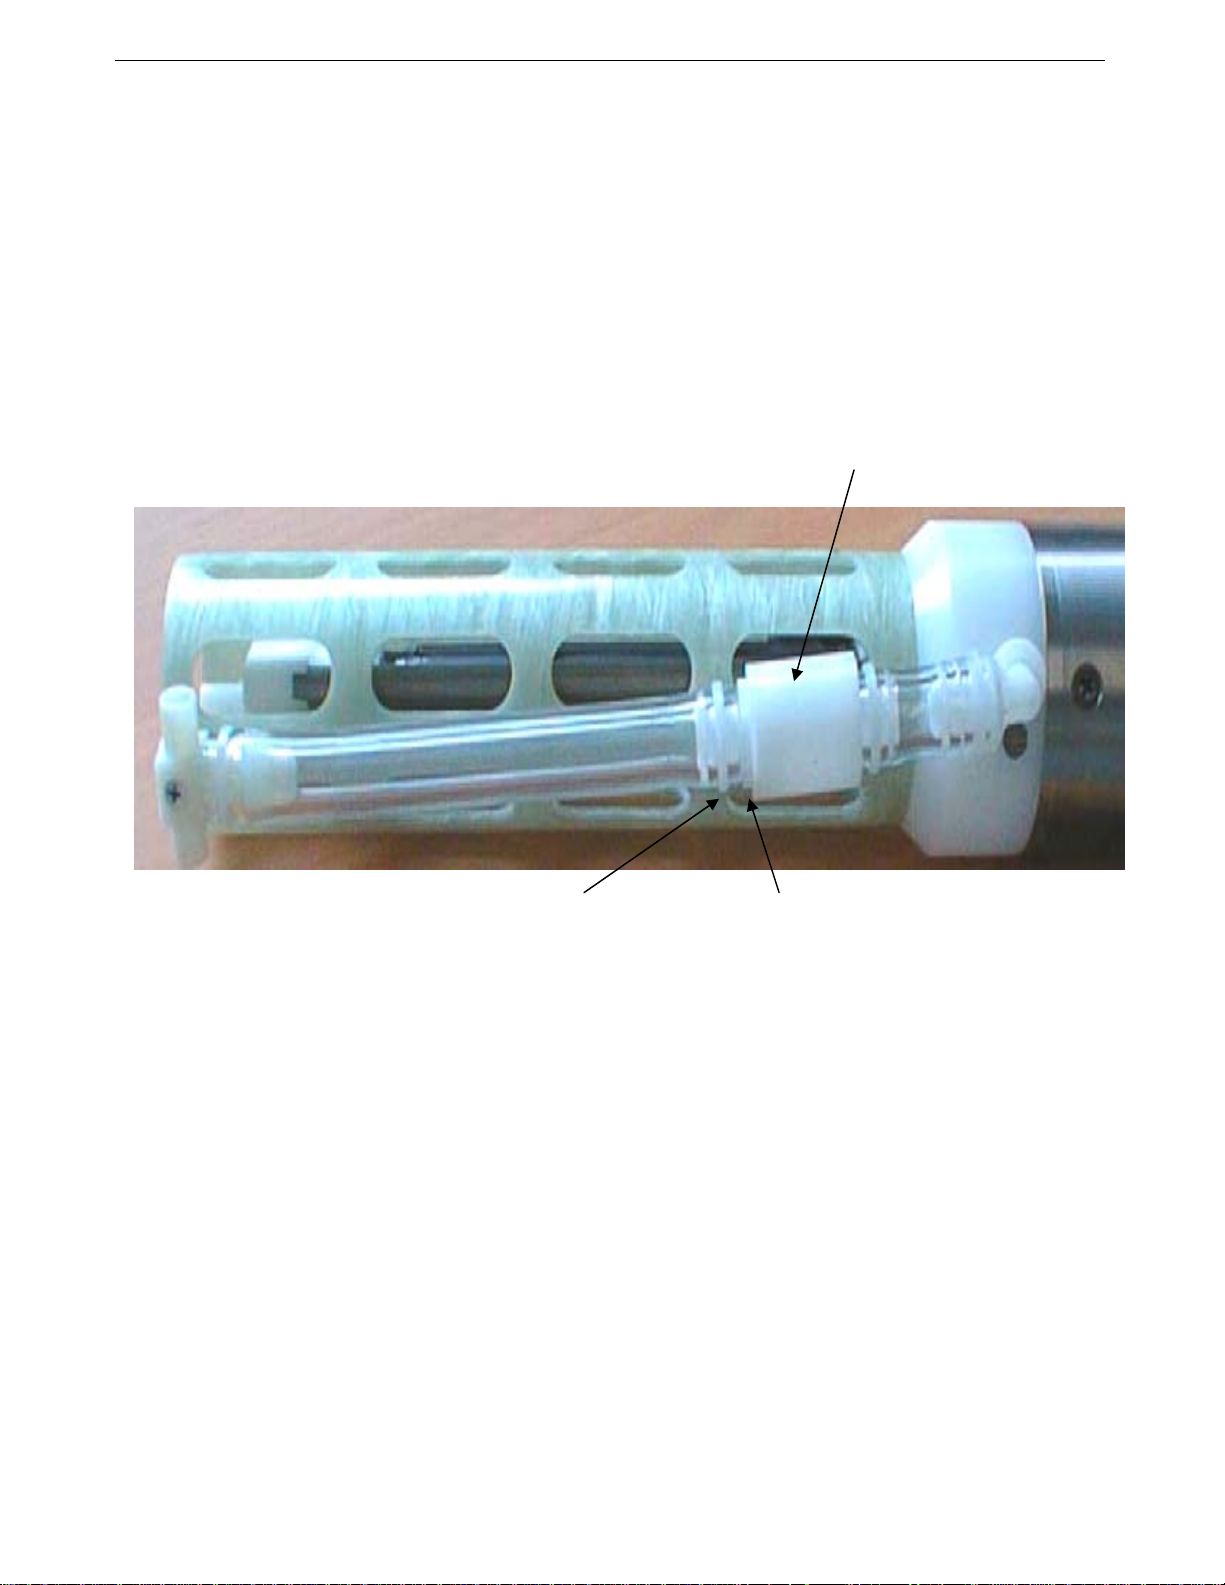
Section 5: Routine Maintenance and Calibration
Anti-Foulant Device in Pump Exhaust Tubing
1. Carefully cut the cable tie securing the Tygon tubing to the anti-foulant
device cap. Slip the Tygon tubing off of the anti-foulant device cap.
2. Unscrew the cap with a socket wrench.
3. Remove the old Anti-Foulant Device. If the old device is difficult to
remove, use needle-nose pliers and carefully break up material.
4. Place the new Anti-Foulant Device in the cup.
5. Rethread the cap onto the cup. Do not over tighten.
6. Slip the Tygon tubing back onto the cap. Secure with a new cable tie.
Anti-foulant device
cup holds AntiFoulant Device
Cut cable tie and slip
Tygon tubing off of antifoulant device cap
Unscrew anti-foulant
device cap from antifoulant device cup
46
Page 47
Section 5: Routine Maintenance and Calibration
Sensor Calibration
Sea-Bird sensors are calibrated by subjecting them to known physical
conditions and measuring the sensor responses. Coefficients are then
computed, which may be used with appropriate algorithms to obtain
Note:
After recalibration, Sea-Bird enters
the new calibration coefficients in
the FastCAT’s EEPROM, and
ships the instrument back to the
user with Calibration Certificates
showing the new coefficients.
The user must enter the
coefficients in the instrument
configuration (.con) file in the
Configure menu in SEASAVE or
SBE Data Processing.
engineering units. The conductivity, temperature, and pressure sensors
on the FastCAT are supplied fully calibrated, with coefficients stored in
EEPROM in the FastCAT and printed on their respective Calibration
Certificates.
We recommend that the FastCAT be returned to Sea-Bird for calibration.
Conductivity Sensor Calibration
The conductivity sensor incorporates a fixed precision resistor in parallel with
the cell. When the cell is dry and in air, the sensor’s electrical circuitry outputs
a frequency representative of the fixed resistor. This frequency is recorded on
the Calibration Certificate and should remain stable (within 1 Hz) over time.
The primary mechanism for calibration drift in conductivity sensors is the
fouling of the cell by chemical or biological deposits. Fouling changes the cell
geometry, resulting in a shift in cell constant.
Accordingly, the most important determinant of long-term sensor accuracy is
the cleanliness of the cell. We recommend that the conductivity sensor be
calibrated before and after deployment, but particularly when the cell has been
exposed to contamination by oil slicks or biological material.
Temperature Sensor Calibration
The primary source of temperature sensor calibration drift is the aging of the
thermistor element. Sensor drift will usually be a few thousandths of a degree
during the first year, and less in subsequent intervals. Sensor drift is not
substantially dependent upon the environmental conditions of use, and —
unlike platinum or copper elements — the thermistor is insensitive to shock.
47
Page 48
Section 5: Routine Maintenance and Calibration
Pressure Sensor Calibration
The FastCAT’s strain-gauge pressure sensor is capable of meeting the
FastCAT’s error specification with some allowance for aging and ambienttemperature induced drift.
Pressure sensors show most of their error as a linear offset from zero. A
technique is provided below for making small corrections to the pressure sensor
calibration using the offset (POFFSET=) calibration coefficient term by
comparing FastCAT pressure output to readings from a barometer.
Allow the FastCAT to equilibrate (with power on) in a reasonably constant
temperature environment for at least 5 hours before starting. Pressure sensors
exhibit a transient change in their output in response to changes in their
environmental temperature. Sea-Bird instrument s are const ruct e d t o minimize
this by thermally decoupling the sensor from the body of the instrument.
However, there is still some residual effect; allowing the FastCAT to equilibrate
Note:
The FastCAT’s pressure sensor is an
absolute sensor, so its raw output
includes the effect of atmospheric
pressure (14.7 psi). As shown on the
Calibration Sheet, Sea-Bird’s
calibration (and resulting calibration
coefficients) is in terms of psia.
However, when outputting pressure in
engineering units, the FastCAT
outputs pressure relative to the ocean
surface (i.e., at the surface the output
pressure is 0 decibars). The FastCAT
uses the following equation to convert
psia to decibars:
Pressure (db) =
[pressure (psia) - 14.7] * 0.689476
Offset Correction Example
Absolute pressure measured by a barometer is 1010.50 mbar. Pressure displayed from FastCAT is -2.5 dbars.
Convert barometer reading to dbars using the relationship: mbar * 0.01 = dbar
Barometer reading = 1010.50 mbar * 0.01 = 10.1050 dbar
The FastCAT’s internal calculations and our processing software output gage pressure, using an assumed
value of 14.7 psi for atmospheric pressure. Convert FastCAT reading from gage to absolute by adding
14.7 psia to the FastCAT’s output:
-2.5 dbars + (14.7 psi * 0.689476 dbar/psia) = -2.5 + 10.13 = 7.635 dbars
Offset = 10.1050 – 7.635 = + 2.47 dbars
Enter offset in FastCAT and in .con file.
before starting will provide the most accurate calibration correction.
1. Place the FastCAT in the orientation it will have when deployed.
2. In SEATERM:
A. Set the pressure offset to 0.0 (POFFSET=0).
B. Send TP to measure the FastCAT pressure 100 times and transmit
converted data in engineering units (decibars).
3. Compare the FastCAT output to the reading from a good barometer at the
same elevation as the FastCAT’s pressure sensor.
Calculate offset = barometer reading – FastCAT reading
4. Enter calculated offset (positive or negative):
• In the FastCAT’s EEPROM, using POFFSET= in SEATERM, and
• In the configuration (.con) file, using SEASAVE or
SBE Data Processing.
For demanding applications, or where the sensor’s air ambient pressure
response has changed significantly, calibration using a dead-weight generator
is recommended. This provides more accurate results, but requires equipment
that may not be readily available. The end cap’s
7
/16-20 straight thread permits
mechanical connection to the pressure source. Use a fitting that has an O-ring
tapered seal, such as Swagelok-200-1-4ST, which conforms to MS16142 boss.
48
Page 49
Section 6: Troubleshooting
Section 6: Troubleshooting
This section reviews common problems in operating the FastCAT, and
provides the most likely causes and solutions.
Problem 1: Unable to Communicate with FastCAT
The S> prompt indicates that communications between the FastCAT and
computer have been established. Before proceeding with troubleshooting,
attempt to establish communications again by clicking Connect on
SEATERM’s toolbar or hitting the Enter key several times.
Cause/Solution 1: The I/O cable connection may be loose. Check the cabling
between the FastCAT and computer for a loose connection.
Cause/Solution 2: The instrument type and/or its communication settings may
not have been entered correctly in SEATERM. Select SBE 49 in the Configure
menu and verify the settings in the Configuration Options dialog box.
The settings should match those on the instrument Configuration Sheet in
the manual.
Cause/Solution 3: The I/O cable may not be the correct one. The I/O cable
supplied with the FastCAT permits connection to standard 9-pin
RS-232 interfaces.
• FastCAT pin 1 goes to DB-9 pin 5
• FastCAT pin 2 goes to DB-9 pin 3
• FastCAT pin 3 goes to DB-9 pin 2
See Section 2: Description of FastCAT for the connector details.
Problem 2: Unreasonable Data
The symptom of this problem is data that contains unreasonable values (for
example, values that are outside the expected range of the data).
Cause/Solution 1: Data with unreasonable values may be caused by:
• Incorrect calibration coefficients in the instrument’s EEPROM (if looking
at data output from the FastCAT in converted format). Verify the
calibration coefficients in EEPROM match the instrument Calibration
Certificates, using DCAL in SEATERM.
• Incorrect calibration coefficients in the .con file (if looking at data
obtained through SEASAVE). Verify the calibration coefficients in the
.con file match the instrument Calibration Certificates.
49
Page 50
Section 6: Troubleshooting
Problem 3: Salinity Lower than Expected
Cause/Solution 1: A fouled conductivity cell will report lower than correct
salinity. Large errors in salinity indicate that the cell is extremely dirty, has
something large lodged in it, or is broken. Proceed as follows:
1. Clean the conductivity cell as described in Conductivity Cell Maintenance
in Section 5: Routine Maintenance and Calibra tion.
2. Remove larger droplets of water by blowing through the conductivity cell.
Do not use compressed air, which typically contains oil vapor.
3. Running the FastCAT in air, use TCR in SEATERM to look at the raw
conductivity frequency. It should be within 1 Hz of the zero conductivity
value printed on the conductivity cell Calibration Sheet. If it is
significantly different, the cell is probably damaged.
50
Page 51
Glossary
Glossary
FastCAT – High-accuracy conductivity, temperature, and pressure sensor.
Fouling – Biological growth in the conductivity cell during deployment.
PCB – Printed Circuit Board.
SBE Data Processing – Sea-Bird’s Win 95/98/NT/2000/XP data
processing software, which calculates temperature, conductivity, and pressure;
derives variables such as salinity and sound velocity; and plots data.
Scan – One data sample containing temperature, conductivity, and pressure.
SEASAVE – Sea-Bird’s Win 95/98/NT/2000/XP software used to acquire,
convert, and display real-time or archived raw data.
SEASOFT-DOS – Sea-Bird’s complete DOS software package, which
includes software for communication, real-time data acquisition, and data
analysis and display. SEASOFT-DOS is not compatible with the FastCAT.
SEASOFT-Win32 – Sea-Bird’s complete Win 95/98/NT/2000/XP software
package, which includes software for communication, real-time data
acquisition, and data analysis and display. SEASOFT-Win32 includes
SEATERM, SeatermAF, SEASAVE, SBE Data Processing, and Plot39.
SEATERM – Sea-Bird’s Win 95/98/NT/2000/XP terminal program used to
communicate with the FastCAT.
Triton X-100 – Reagent grade non-ionic surfactant (detergent), used for
cleaning the conductivity cell. Triton can be ordered from Sea-Bird, but should
also be available locally from chemical supply or laboratory products
companies. Triton is manufactured by J.T. Baker (Mallinkrodt Baker Inc.); see
http://www.jtbaker.com/distrib/distrib.asp?seg=lab for local distributors.
51
Page 52
Appendix I: Functional Description and Circuitry
Appendix I:
Functional Description and Circuitry
Sensors
The SBE 49 embodies the same sensor elements (3-electrode, 2-terminal,
borosilicate glass cell, and pressure-protected thermistor) previously
employed in Sea-Bird’s modular SBE 3 and SBE 4 sensors and in the
SEACAT and SEACATplus. The FastCAT uses three independent channels to
digitize temperature, conductivity, and pressure concurrently.
The pressure sensor is a Druck strain-gauge sensor.
Sensor Interface
Temperature is acquired by applying an AC excitation to a bridge circuit
containing an ultra-stable aged thermistor with a drift rate of less than 0.002 ºC
per year. The other elements in the bridge are VISHAY precision resistors.
A 24-bit A/D converter digitizes the output of the bridge. AC excitation and
ratiometric comparison avoids errors caused by parasitic thermocouples, offset
voltages, leakage currents, and reference e rrors.
Conductivity is acquired using an ultra-precision Wien-Bridge oscillator to
generate a frequency output in response to changes in conductivity.
Strain-gauge pressure is acquired by applying an AC excitation to the
pressure bridge. A 24-bit A/D converter di gi t i zes the out p ut of the bri dge.
AC excitation and ratiometric comparison avoids errors caused by parasitic
thermocouples, offset voltages, leakage currents, and reference errors.
A silicon diode embedded in the pressure bridge is used to measure the
temperature of the pressure bridge. This temperature is used to perform offset
and span corrections on the measured pressure signal.
52
Page 53
Appendix II: Electronics Disassembly/Reassembly
Appendix II: Electronics Disassembly/Reassembly
Disassembly
Remove screw
(2 places)
Remove screw (3 places)
Pry off end cap using
screwdriver in slots
1. Remove the connector end cap:
A. Wipe the outside of the end cap and housing dry, being careful to
remove any water at the seam between them.
B. Remove the two Phillips-head screws holding the connector end cap
to the housing.
C. Using straight screwdrivers in the slots, carefully pry off the end cap.
Note that the end cap and electronics are electrically connected with
edge connectors, and the end cap will not twist off.
D. Remove any water from the O-rings and mating surfaces inside the
housing with a lint-free cloth or tissue.
E. Be careful to protect the O-rings from damage or contamination.
2. Remove the housing:
A. Wipe the outside of the sensor end cap and housing dry, being careful
to remove any water at the seam between them.
B. Remove the three Phillips-head screws holding the housing to the
sensor end cap.
C. Slide the end cap and attached electronics out of the housing.
D. Remove any water from the O-rings and mating surfaces inside the
housing with a lint-free cloth or tissue.
E. Be careful to protect the O-rings from damage or contamination.
Reassembly
Note:
Before delivery, a desiccant package
is placed in the housing, and the
electronics chamber is filled with dry
Argon gas. These measures help
prevent condensation. To ensure
proper functioning:
1. Install a new desiccant bag each
time you open the housing. If a
new bag is not available, see
Application Note 71: Desiccant
Use and Regeneration (drying).
2. If possible, dr y gas backfill each
time you open the housing. If you
cannot, wait at least 24 hours
before redeploying, to allow the
desiccant to remove any moisture
from the housing.
1. Remove any water from the end cap O-rings and mating surfaces in the
housing with a lint-free cloth or tissue. Inspect the O-rings and mating
surfaces for dirt, nicks, and cuts. Clean or replace as necessary. Apply a
light coat of O-ring lubricant (Parker Super O Lube) to the O-rings and
mating surfaces.
2. Reinstall the housing:
A. Carefully fit the end cap and electronics into the housing until the
O-rings are fully seated.
B. Reinstall the three screws to secure the housing to the sensor end cap.
3. Reinstall the connector end cap:
A. Line up the alignment pin with the notch in the end cap. Verify the
pin/notch and screw holes are properly aligned.
B. Carefully fit the end cap into the housing until the edge connectors
mate and the O-rings are fully seated.
C. Reinstall the two screws to secure the housing to the end cap.
4. No user-programmable setup parameters should have been affected by the
electronics disassembly (send DS to verify).
53
Page 54
Appendix III: Command Summary
Appendix III: Command Summary
CATEGORY COMMAND DESCRIPTION
Status DS
BAUD=x
OUTPUTFORMAT=x
Setup
Autonomous
Sampling
Polled
Sampling
Testing
Takes and
outputs
100 samples for
each test. Press
Esc key or Stop
on Toolbar to
stop test.
OUTPUTSAL=x
OUTPUTSV=x
SETDEFAULTS
NAVG=x
MINCONDFREQ=x
PUMPDELAY=x
PROCESSREALTIME=x
TADVANCE=x
ALPHA=x
TAU=x
AUTORUN=x
START
STOP
PUMPON
PUMPOFF
TS
TT
TC
TP
TTR
TCR
TPR
Display status and setup parameters.
x= baud rate (1200, 2400, 4800, 9600, 19200,
or 38400). Default 9600.
x=0: output raw data in Hex.
x=1: output converted data in Hex.
x=2: output raw data in decimal.
x=3: output converted data in decimal. Default.
x=Y: Calculate and output salinity (psu). Only
applies if OUTPUTFORMAT=3. Default.
x=N: Do not calculate and output salinity.
x=Y: Calculate and output sound velocity (m/sec).
Only applies if OUTPUTFORMAT=3. Default.
x=N: Do not calculate and output sound velocity.
Reset to default values:
OUTPUTSAL=Y, OUTPUTSV=Y, NAVG=1,
MINCONDFREQ=3000, PUMPDELAY=30,
PROCESSREALTIME=Y, TADVANCE=0.0625,
ALPHA=0.03, TAU=7.0, AUTORUN=N
x= number of samples to average. FastCAT samples
at 16 Hz and averages NAVG samples. Default =1.
x= minimum conductivity frequency (Hz) to enable
pump turn-on. Pump stops when frequency drops
below x. Default 3000 Hz; factory set to
(0 conductivity frequency + 500 Hz).
x= time (seconds) to wait after minimum
conductivity frequency is reached before turning
pump on. Default 30 seconds.
x=Y: Apply alignment, filtering, and conductivity
cell thermal mass corrections to data. Only applies if
OUTPUTFORMAT=1 or 3. Default.
x=N: Do not apply corrections to data.
x= Time to advance temperature data relative
to conductivity and pressure data. Range 0 to
0.125 seconds; default 0.0625 seconds. Only applies
if PROCESSREALTIME=Y and
OUTPUTFORMAT=1 or 3.
x= Conductivity cell thermal mass alpha correction.
Range 0.02 to 0.05; default 0.03. Only applies if
PROCESSREALTIME=Y and
OUTPUTFORMAT=1 or 3.
x= Conductivity cell thermal mass tau correction.
Range 5.0 to 10.0; default 7.0. Only applies if
PROCESSREALTIME=Y and
OUTPUTFORMAT=1 or 3.
x=N: Wait for command when power applied.
Default.
x=Y: Start autonomous sampling when
power applied.
Start autonomous sampling now.
Stop autonomous sampling. Press Enter key to get S>
prompt before entering STOP.
Turn pump on.
Turn pump off.
Take 1 sample and output data.
Measure temperature, transmit converted data.
Measure conductivity, transmit converted data.
Measure pressure, transmit converted data.
Measure temperature, transmit raw data
Measure conductivity, transmit raw data.
Measure pressure, transmit raw data.
OUTPUTFORMAT=3,
.
54
Page 55
Appendix III: Command Summary
CATEGORY COMMAND DESCRIPTION
Display calibration coefficients; all coefficients and dates listed
below are included in display. Use individual commands below
to modify a particular coefficient or date.
S=Temperature calibration date.
F=Temperature A0.
F=Temperature A1.
F=Temperature A2.
F=Temperature A3.
F=Temperature offset correction.
S=Conductivity calibration date.
F=Conductivity G.
F=Conductivity H.
F=Conductivity I.
F=Conductivity J.
F=Conductivity pcor.
F=Conductivity tcor.
F=Conductivity slope correction.
S=Pressure calibration date.
F=Pressure sensor full scale range (psi).
F=Pressure offset correction.
F=Pressure A0.
F=Pressure A1.
F=Pressure A2.
F=Pressure temperature A0.
F=Pressure temperature A1.
F=Pressure temperature A2.
F=Pressure temperature compensation ptca0.
F=Pressure temperature compensation ptca1.
F=Pressure temperature compensation ptca2.
F=Pressure temperature compensation ptcb0.
F=Pressure temperature compensation ptcb1.
F=Pressure temperature compensation ptcb2.
Coefficients
(F=floating
point number;
S=string with
no spaces)
Dates shown
are when
calibrations
were
performed.
Calibration
coefficients
are initially
factory-set and
should agree
with
Calibration
Certificates
shipped with
FastCAT.
DCAL
TCALDATE=S
TAO=F
TA1=F
TA2=F
TA3=F
TOFFSET=F
CCALDATE=S
CG=F
CH=F
CI=F
CJ=F
CPCOR=F
CTCOR=F
CSLOPE=F
PCALDATE=S
PRANGE=F
POFFSET=F
PA0=F
PA1=F
PA2=F
PTEMPA0=F
PTEMPA1=F
PTEMPA2=F
PTCA0=F
PTCA1=F
PTCA2=F
PTCB0=F
PTCB1=F
PTCB2=F
55
Page 56
Appendix IV: AF24173 Anti-Foulant Device
Appendix IV : AF24173 Anti-Foulant Device
AF24173 Anti-Foulant Devices supplied for user replacement are supplied in
polyethylene bags displaying the following label:
FOR USE ONLY IN SEA-BIRD ELECTRONICS' CONDUCTIVITY SENSORS TO CONTROL THE GROWTH OF AQUATIC ORGANISMS
WITHIN ELECTRONIC CONDUCTIVITY SENSORS.
ACTIVE INGREDIENT:
Bis(tributyltin) oxide…………..…………………………..... 53.0%
OTHER INGREDIENTS: ………………………………..... 47.0%
Total………………………………………………………..... 100.0%
DANGER
See the complete label within the Conductivity Instrument Manual for Additional Precautionary Statements and Information on the Handling, Storage, and
Disposal of this Product.
Net Contents: Two anti-foulant devices
Sea-Bird Electronics, Inc. EPA Registration No. 74489-1
1808 - 136
Bellevue, WA 98005
th
Place Northeast EPA Establishment No. 74489-WA-1
AF24173 ANTI-FOULANT DEVICE
56
Page 57
Appendix IV: AF24173 Anti-Foulant Device
AF24173 Anti-Foulant Device
FOR USE ONLY IN SEA-BIRD ELECTRONICS’ CONDUCTIVITY SENSORS TO CONTROL
THE GROWTH OF AQUATIC ORGANISMS WITHIN ELECTRONIC CONDUCTIVITY
SENSORS.
ACTIVE INGREDIENT:
Bis(tributyltin) oxide…………..…………………………..... 53.0%
OTHER INGREDIENTS: ………………………………..... 47.0%
Total………………………………………………………..... 100.0%
DANGER
See Precautionary Statements for additional information.
FIRST AID
If on skin or
clothing
• Take off contaminated clothing.
• Rinse skin immediately with plenty of water for15-20 minutes.
• Call a poison control center or doctor for treatment advice.
If swallowed
• Call poison control center or doctor immediately for treatment advice.
• Have person drink several glasses of water.
• Do not induce vomiting.
• Do not give anything by mouth to an unconscious person.
If in eyes
• Hold eye open and rinse slowly and gently with water for 15-20
minutes.
• Remove contact lenses, if present, after the first 5 minutes, then continue
rinsing eye.
• Call a poison control center or doctor for treatment advice.
HOT LINE NUMBER
Note to Physician Probable mucosal damage may contraindicate the use of gastric lavage.
Have the product container or label with you when calling a poison control center or doctor, or
going for treatment. For further information call National Pesticide Telecommunications
Network (NPTN) at 1-800-858-7378.
Net Contents: Two anti-foulant devices
Sea-Bird Electronics, Inc. EPA Registration No. 74489-1
1808 - 136
Bellevue, WA 98005
th
Place Northeast EPA Establishment No. 74489-WA-1
57
Page 58
Appendix IV: AF24173 Anti-Foulant Device
PRECAUTIONARY STATEMENTS
HAZARD TO HUMANS AND DOMESTIC ANIMALS
DANGER
Corrosive - Causes irreversible eye damage and skin burns. Harmful if swallowed. Harmful if
absorbed through the skin or inhaled. Prolonged or frequently repeated contact may cause allergic
reactions in some individuals. Wash thoroughly with soap and water after handling.
PERSONAL PROTECTIVE EQUIPMENT
USER SAFETY RECOMMENDATIONS
Users should:
• Remove clothing immediately if pesticide gets inside. Then wash thoroughly and put on
clean clothing.
• Wear protective gloves (rubber or latex), goggles or other eye protection, and clothing to
minimize contact.
• Follow manufacturer’s instructions for cleaning and maintaining PPE. If no such instructions
for washables, use detergent and hot water. Keep and wash PPE separately from other
laundry.
• Wash hands with soap and water before eating, drinking, chewing gum, using tobacco or
using the toilet.
ENVIRONMENTAL HAZARDS
Do not discharge effluent containing this product into lakes, streams, ponds, estuaries, oceans, or other
waters unless in accordance with the requirements of a National Pollutant Discharge Elimination
System (NPDES) permit and the permitting authority has been notified in writing prior to discharge.
Do not discharge effluent containing this product to sewer systems without previously notifying the
local sewage treatment plant authority. For guidance contact your State Water Board or Regional
Office of EPA. This material is toxic to fish. Do not contaminate water when cleaning equipment or
disposing of equipment washwaters.
PHYSICAL OR CHEMICAL HAZARDS
Do not use or store near heat or open flame. Avoid contact with acids and oxidizers.
DIRECTIONS FOR USE
It is a violation of Federal Law to use this product in a manner inconsistent with its labeling. For use
only in Sea-Bird Electronics’ conductivity sensors. Read installation instructions in the applicable
Conductivity Instrument Manual.
58
Page 59
Appendix IV: AF24173 Anti-Foulant Device
STORAGE AND DISPOSAL
PESTICIDE STORAGE: Store in original container in a cool, dry place. Prevent exposure to
heat or flame. Do not store near acids or oxidizers. Keep container tightly closed.
PESTICIDE SPILL PROCEDURE: In case of a spill, absorb spills with absorbent material. Put
saturated absorbent material to a labeled container for treatment or disposal.
PESTICIDE DISPOSAL: Pesticide that cannot be used according to label instructions must be
disposed of according to Federal or approved State procedures under Subtitle C of the Resource
Conservation and Recovery Act.
CONTAINER DISPOSAL: Dispose of in a sanitary landfill or by other approved State and
Local procedures.
Sea-Bird Electronics/label revised 01-31-05
59
Page 60
Appendix V: Real-Time Data Correction Algorithms
Appendix V: Real-Time Data Correction Algorithms
Note:
Real-time processing
recommendations are summarized
in Real-Time Data Corrections
in Section 4: Deploying and
Operating FastCAT.
Aligning, filtering, and correcting for conductivity cell thermal mass in postprocessing allows you to make adjustments to the measured data before
calculating derived parameters. SBE Data Processing, part of our SEAS OFT
suite, can perform this processing on recorded data, if a complete C, T, and P
time series is recorded. However, the FastCAT, which samples and transmits
data at 16 Hz, is frequently integrated by the customer with an AUV or ROV.
The AUV/ROV may record data on command, with uneven time intervals
between each recorded measurement. The lack of a true time series from the
FastCAT for these applications prevents aligning, filtering, and correcting for
cell thermal mass in post-processing.
Therefore, the FastCAT can be programmed to process data in real-time if
sampling autonomously. This provides T, C, and P output that is already
aligned, filtered, and corrected for cell thermal mass, and also provides
calculated and output salinity and sound velocity (if applicable) based on these
corrected values.
Aligning Data
The FastCAT aligns temperature data in time, relative to conductivity and
pressure. This ensures that calculations of salinity, sound velocity, and other
derived variables are made using measurements from the same parcel of water.
There are three principal causes of misalignment of CTD measurements:
• physical misalignment of the sensors in depth
• inherent time delay (time constants) of the sensor responses
• water transit time delay in the pumped plumbing line - the time it takes
the parcel of water to go through the plumbing to each sensor (or, for freeflushing sensors, the corresponding flushing delay, which depends on
profiling speed)
In the FastCAT, temperature data is usually misaligned with respect to
conductivity and pressure. Advancing temperature relative to conductiv ity and
pressure can compensate. The recommended temperature advance value for a
typical FastCAT is 0.0625 seconds, but the user can select a value ranging
from 0 to 0.125 seconds. When measurements are properly aligned, salinity
spiking (and density) errors are minimized.
60
Page 61
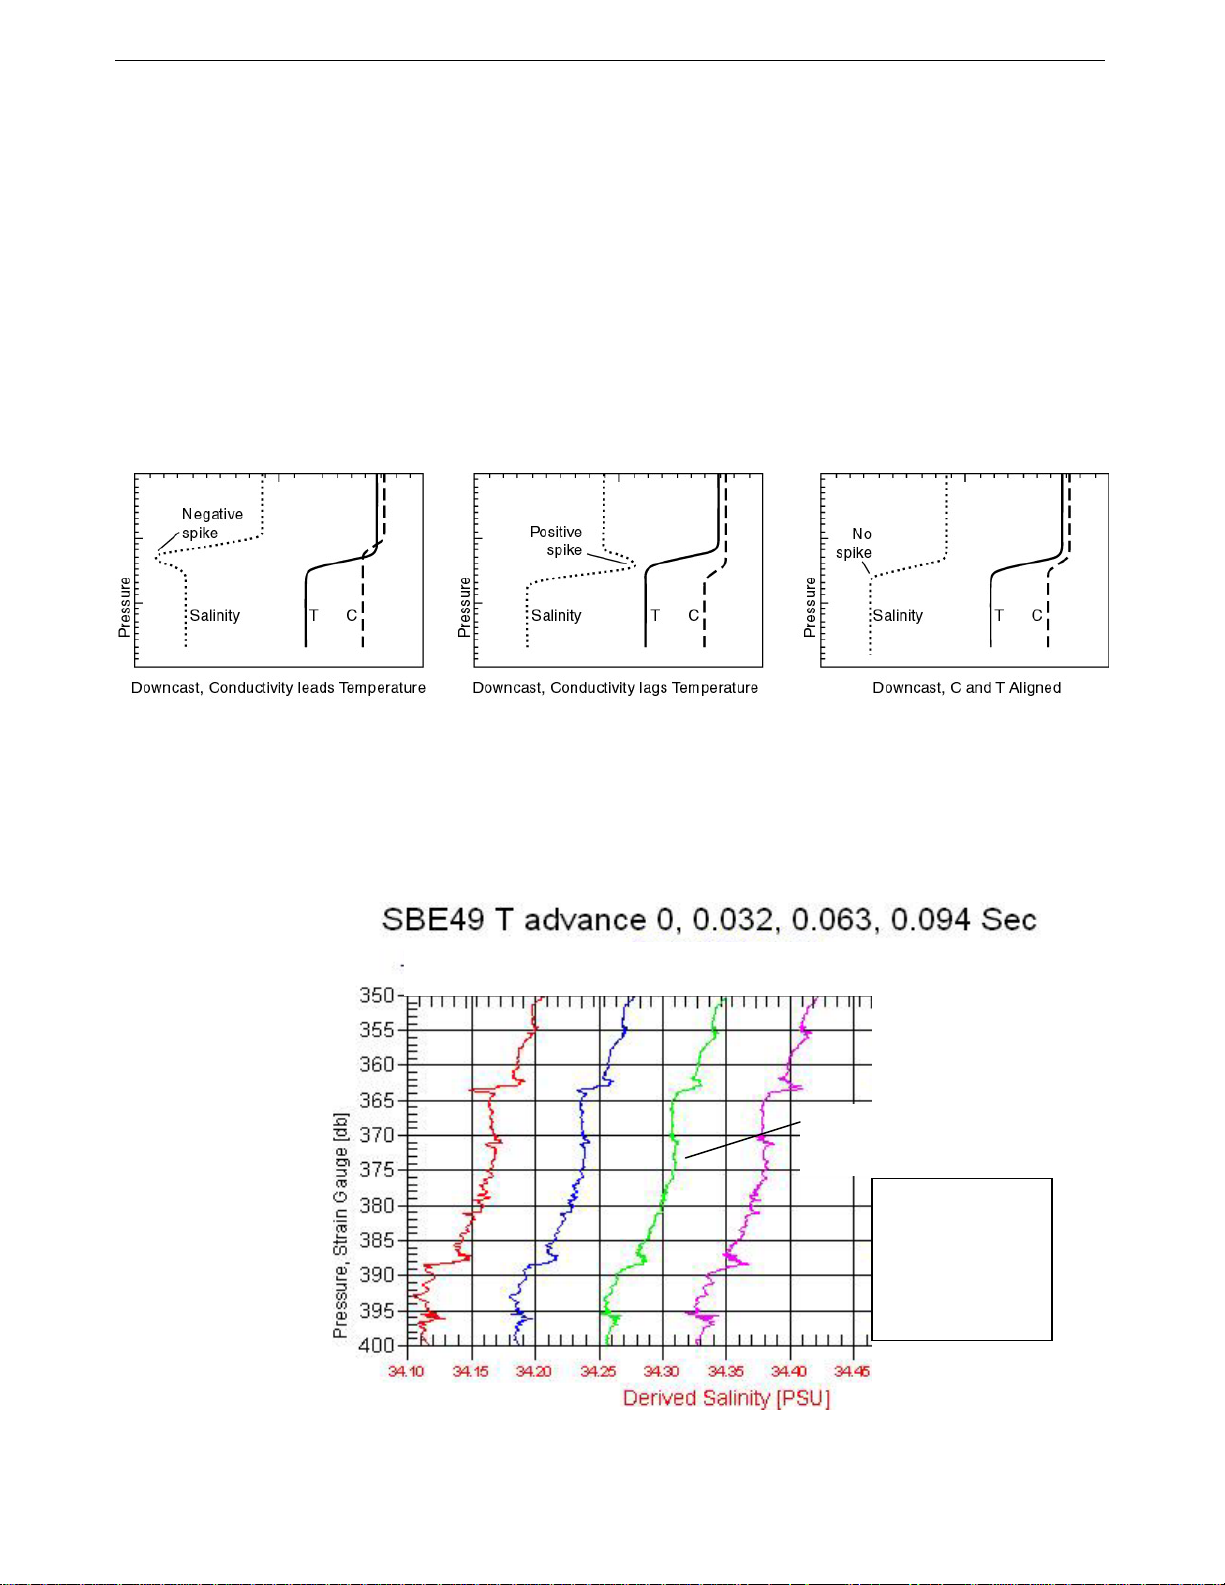
Appendix V: Real-Time Data Correction Algorithms
The best diagnostic of proper alignment is the elimination of salinity spikes
that coincide with very sharp temperature steps. Some experimentation with
different advances is required to find the best alignment. To determine the best
alignment for your FastCAT, plot 10 meters of uncorrected temperature and
salinity data at a depth that contains a very sharp temperature step. For the
downcast, when temperature and salinity increase with increasin g pressure:
• A negative salinity spike at the step means that temperature lags
conductivity (temperature sensor sees step after conductivity sensor does),
and that temperature should be advanced a positive number of seconds.
• Conversely, a positive salinity spike means that temperature leads
conductivity (temperature sensors sees step before conductivity sensor
does), and that temperature should be advanced a negative number of
seconds. Note that this behavior is not expected for a FastCAT, because of
the inherent characteristics of the sensor response times and plumbing.
Therefore, the FastCAT’s real-time data processing does not support a
negative temperature advance; see the SBE Data Processing manual to
perform this correction in post-processing if necessary.
Shown below is a comparison of FastCAT data with different temperature
advances; the best results (least salinity spiking) are seen with an advance of
0.0625 seconds.
Temperature advance 0 0.032 0.0625 0.094 seconds
Spiking minimized with
0.0625 second advance
Note: Data shown
has been filtered,
had conductivity cell
thermal mass
corrections applied,
and loops caused by
pressure reversals
removed.
61
Page 62
Appendix V: Real-Time Data Correction Algorithms
Filtering Data
Filtering smoothes the data, to match the temperature and conductivity sensor
time constants. In post-processing, Sea-Bird recommends using a low-pass
filter (Filter module in SBE Data Processing) on recorded FastCAT data, with
a time constant of 0.085 seconds for both temperature and conductivity. This
filter algorithm cannot be implemented for real-time data processing in the
FastCAT, because the low-pass filter is run forward through the data (an
impossible task when processing in real-time) and then run backward through
the data. Instead, a 5-scan cosine window filter (based on the Window Filter
module in SBE Data Processing) was implemented for real-time data
processing in the FastCAT; this window filter provides results comparable to
the low-pass filter.
The window filter calculates a weighted average of data values about a center
point, using the following transfer function:
L/2
y(n) = Σ w(k) x(n-k)
k=-L/2
It then replaces the data value at the center point with this average.
The window filtering process follows:
Note:
In the window filter equations:
• L = window length in scans
= 5 for FastCAT real-time
data processing algorithm
• n = window index, -( [L-1] / 2) to
+( [L-1] / 2), with 0 the center
point of the window
• w(n) = set of window weights
1. Calculate cosine filter weights (see the equations below).
w(n) = 1 for n = 0
w(n) = cos for n = - . .-1, 1 . .
n x π
L + 1
L - 1
2
L - 1
2
2. Normalize filter weights to sum to 1.
Applying Conductivity Cell Thermal Mass Correction to Data
The FastCAT uses a recursive filter to remove conductivity cell thermal mass
effects from the measured conductivity. In areas with steep temperature
gradients, the correction is on the order of 0.005 PSU. In other areas the
correction is negligible. Recommended values for alpha and tau (tau = 1 / beta)
for the FastCAT are 0.03 and 7.0 respectively.
The algorithm, based on the Cell Thermal Mass module in SBE Data
Processing, is:
dt = temperature - previous temperature
ctm = -1.0 * b * previous ctm + a * (dc/dt) * dt
corrected conductivity = c + ctm
where:
a = 2 * alpha / (sample interval * beta + 2)
b = 1 - (2 * a / alpha)
dc/dt = 0.1 * (1 + 0.006 * [temperature - 20])
62
Page 63
Appendix VI: Replacement Parts
b
Appendix VI: Replacement Parts
Part
Number
4-pin RMG-4FS to 9-pin
801385
17046.1
17043 Locking sleeve *
801206
171398.1
171192
171888
30411 Triton X-100
801347 /
801542
231513
231514
232055 T-C Duct top
232056 T-C Duct base
232395 Straight pump exhaust
231408 Tee pump exhaust
30132
30239
30536
DB-9S I/O cable with
power leads, 2.4 m (8 ft)*
4-pin RMG-4FS dummy
plug with locking sleeve *
4-pin MCIL-4FS (wetpluggable connector) to
9-pin DB-9S I/O cable
with power leads,
2.4 m (8 ft)
4-pin MCIL-4FS
(wet-pluggable connector)
dummy plug with
locking sleeve
Locking sleeve (wetpluggable connector)
25-pin DB-25S to 9-pin
DB-9P cable adapter
AF24173
Anti-Foulant Device
Anti-foulant device cup
on pump exhaust
plumbing
Anti-foulant device cap
on pump exhaust
plumbing
Screw, 4-40 x 3/4 flat
Phillips-head, stainless
Washer, #4 nylon
WN-4
Tygon tubing,
3/8” ID x 5/8” OD
Part Application Description
*For standard bulkhead connector.
Continued on next page
From FastCAT to computer/
controller and power supply
For storage when I/O cable
not used
Locks I/O cable or dummy plug
in place
From FastCAT to computer/
controller and power supply
For storage when I/O cable not
connected
Locks I/O cable or dummy plug
in place
For use with computer with
DB-25 connector
Octyl Phenol Ethoxylate – Reagent
grade non-ionic cleaning solution
for conductivity cell (supplied in
100% strength; dilute as directed)
is(tributyltin) oxide device inserted
into anti-foulant device cup
Holds optional
AF24173 Anti-Foulant Device
Secures optional AF24173
Anti-Foulant Device in cup
T-C Duct, also secures optional
AF24173 Anti-Foulant Device
in base
T-C Duct, holds optional AF24173
Anti-Foulant Device
Straight (standard) exhaust fitting,
mounts to sensor guard
Tee exhaust fitting for slow
profiling applications, mounts to
sensor guard
Secures pump exhaust fitting to
sensor guard
For 30132 screw, placed between
tee and sensor guard
Exhaust plumbing
Quantity
in FastCAT
1
1
1
1
1
1
1
1
1 (set of 2)
1
1
1
1
1
1
2
63
Page 64
Appendix VI: Replacement Parts
Continued from previous page
Part
Number
60037 Spare parts kit
50312
Anti-foulant device inline cap/cup assembly
Part Application Description
Assorted o-rings and hardware,
including:
• 231408 Exhaust tee (for slow
profiling applications)
• 30132 Machine screw, 4-40 x ¾
FH SS (secure exhaust tee to
sensor guard)
• 31081 Machine screw, 4-40 x ½
SHSS (retaining rod screw)
• 30389 Cable tie, 4 inch (secure
tubing to exhaust tee)
• 30857 Parker, 2-033E515-70
(o-rings for both end caps)
• 30859 Machine Screw,
8-32 x 3/8” FH Ti (secure end
caps to housing)
• 30947 Machine Screw, 2-56 x ½
FH SS (secure AF24173 antifoulant device chamber top on
sensor head)
• 30992 Machine Screw, 2-56 x 5/8
PH Phillip SS (secure T-C Duct
top to base)
• 31076 O-ring, Parker 2-003
E515-80 (for 30992 screws)
• 31182 O-ring, NAS1611-021
Ethylene Propyle n e (T-C Duct
base to top o-ring seal)
Assorted parts, including:
• 231513 In-line Anti-Foulant cup
(for AF24173 Anti-Foulant
Device)
• 231514 In-line Anti-Foulant cap
(seals AF24173 Anti-Foulant
Device in cup)
• 30072 O-ring, 2-017 N674-70
(seal between cap and cup)
• 30536 Tubing, 3/8” ID x 5/8” OD
(plumbing)
• 30389 Cable Tie, 4”, Richco
(secures plumbing to cap, cup,
and CTD barbs)
Quantity
in FastCAT
-
-
64
Page 65
Index
Index
.
.con file · 37
A
About Sea-Bird · 5
Anti-Foulant Devices · 56
replacing · 44, 45
AUV · 40
B
Baud rate · 22, 39
C
Cable length · 22, 23
Calibration · 47
Circuitry · 52
Cleaning · 43
Command summary · 54
Commands
calibration coefficients · 30
descriptions · 24
sampling · 27, 29
setup · 26
status · 25
testing · 29
Communication defaults · 15
Configuration file · 37
Connector · 10, 42
Corrections
real-time · 21, 60
Corrosion precautions · 42
D
Data corrections
real-time · 21, 60
Data output format · 31
Data processing · 39, 40
real-time · 21, 60
Data transmission rate · 22
Deployment
installation · 36
optimizing data quality · 33
setup · 35
Description · 7
Dimensions · 10
E
Electronics disassembly/reassembly · 53
End cap · 10, 42
F
Format
data output · 31
Functional description · 52
G
Glossary · 51
M
Maintenance · 42
Modes · See Sampling modes
P
Parts
replacement · 63
Power · 23
Pressure sensor
maintenance · 43
Processing data · 39, 40
Q
Quick start · 5
R
Real-time corrections · 21, 60
Real-time data acquisition · 37, 40
Real-time processing · 21, 60
Recovery
physical handling · 41
Replacement parts · 63
ROV · 40
S
Sampling
autonomous · 19
polled · 18
Sampling modes · 17
SBE Data Processing · 8, 12, 39, 40
SEASAVE · 8, 12, 37
SEASOFT-DOS · 8
SEASOFT-Win32 · 8, 12
SEATERM · 8, 12, 13
main screen · 13
toolbar buttons · 14
Sensors · 9
Software · 8
installation · 12
Specifications · 9
Storage · 43
System description · 7
65
Page 66
Index
T
Test
power and communications · 12
setup · 12
Triton · 51
U
Unpacking FastCAT · 6
66
 Loading...