

Page 1
Physik Instrumente (PI) GmbH & Co. KG, Auf der Roemerstrasse 1, 76228 Karlsruhe, Germany
PZ253E
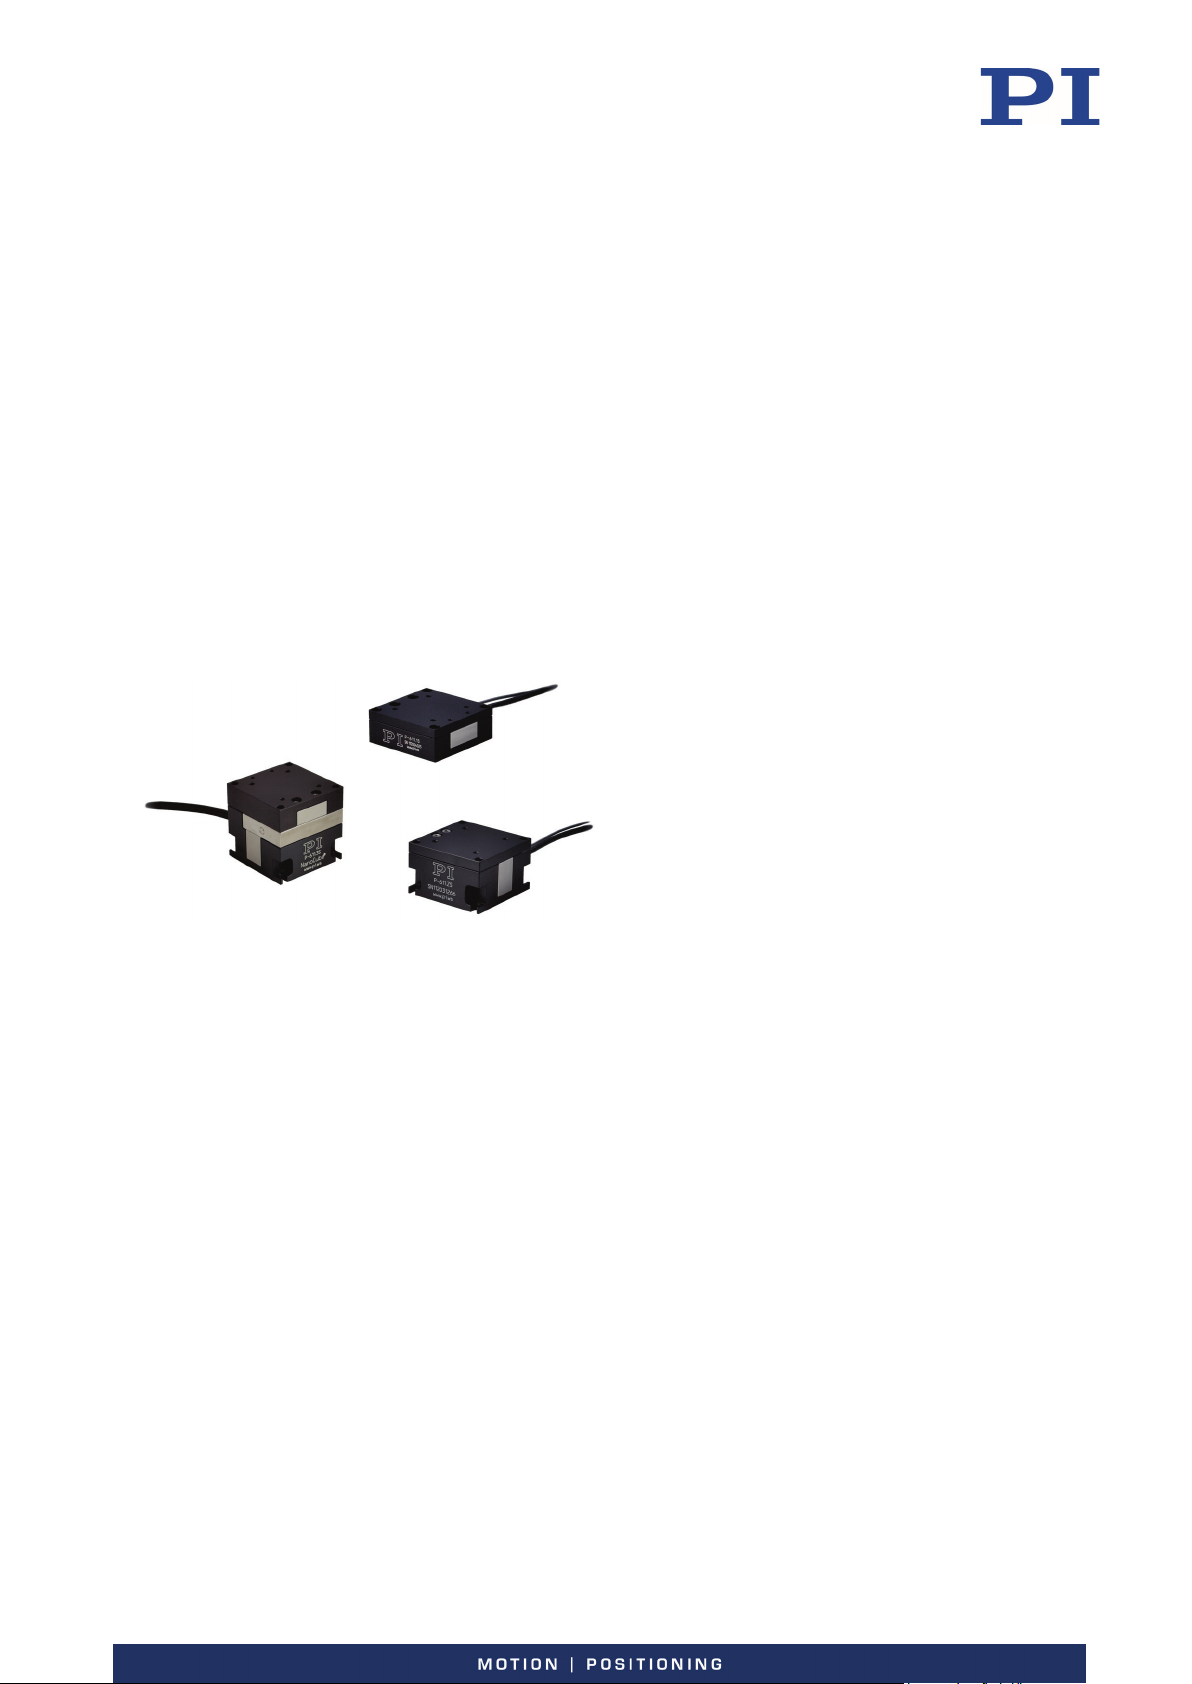
P-611 Positioning Systems
User Manual
Version: 1.1.0
Date: 25.03.2019
This document describes the following products:
P-611.1
Linear piezo positioning system
P-611.1S/.10
P-611.XZ / P-611.2
XZ and XYZ nanopositioner
P-611.2S/.20/.XZS/.XZ0
P-611.3
NanoCube® XYZ system
P-611.3S/.3SF/.3O/.3OF
P-611.Z
Piezo Z stage
P-611.ZS/.Z0
.1S/.10/.2S/.20/.XZS/.XZ0/.ZS/.Z0
= with LEMO connector(s)
.3S/.3SF/.3O/.3OF
= with D-sub connector
Phone +49 721 4846-0, Fax +49 721 4846-1019, Email [email protected], www.pi.ws
Page 2
The following company names and brands are registered trademarks of Physik Instrumente (PI) GmbH & Co.
KG:
PI®, NanoCube®, PICMA®, PILine®, NEXLINE®, PiezoWalk®, NEXACT®, Picoactuator®, PInano®, PIMag®,
Q-Motion®
The patents held by PI are found in our patent list:
http://www.physikinstrumente.com/en/about-pi/patents
© 2019 Physik Instrumente (PI) GmbH & Co. KG, Karlsruhe, Germany. The text, photographs and drawings in
this manual are protected by copyright. With regard thereto, Physik Instrumente (PI) GmbH & Co. KG retains
all the rights. The use of any text, images and drawings is permitted only in part and only when indicating the
source.
Original instructions
First printing: 25.03.2019
Document number: PZ253E, CBo, Version 1.1.0
Subject to change without notice. This manual is superseded by any new release. The latest release is
available for download (p. 3) on our website.
Page 3
Contents
1 About this Document 1
1.1 Objective and Target Audience of this User Manual.................................................. 1
1.2 Symbols and Typographic Conventions...................................................................... 1
1.3 Figures ........................................................................................................................ 2
1.4 Other Applicable Documents ..................................................................................... 2
1.5 Downloading Manuals ................................................................................................ 3
2 Safety 5
2.1 Intended Use .............................................................................................................. 5
2.2 General Safety Instructions ........................................................................................ 6
2.3 Organizational Measures ............................................................................................ 7
3 Product Description 9
3.1 Model Overview ......................................................................................................... 9
3.2 Product View ............................................................................................................ 10
3.3 Product Labeling ....................................................................................................... 12
3.4 Scope of Delivery ...................................................................................................... 12
3.5 Suitable Electronics .................................................................................................. 13
3.6 Accessories ............................................................................................................... 13
3.7 Technical Features .................................................................................................... 13
3.7.1 PICMA® Piezo Actuators .............................................................................. 13
3.7.2 Flexure Guides ............................................................................................. 14
3.7.3 Strain Gauge Sensors (SGS) ......................................................................... 14
4 Unpacking 15
5 Installation 17
5.1 General Notes on Installation ................................................................................... 17
5.2 Connecting the P-611 to the Protective Earth Conductor ....................................... 18
5.3 Mounting the P-611 ................................................................................................. 20
5.4 Fixing the Load .......................................................................................................... 22
6 Startup and Operation 25
6.1 General Notes on Startup and Operation ................................................................ 25
6.2 Operating the P-611 ................................................................................................. 26
6.3 Discharging the P-611 ............................................................................................... 27
Page 4
7 Maintenance 29
7.1 General Notes on Maintenance ............................................................................... 29
7.2 Cleaning the P-611 ................................................................................................... 29
8 Troubleshooting 31
9 Customer Service 33
10 Technical Data 35
10.1 Specifications ............................................................................................................ 35
10.1.1 Data Table .................................................................................................... 35
10.1.2 Maximum Ratings ........................................................................................ 39
10.1.3 Ambient Conditions and Classifications ...................................................... 40
10.2 Dimensions ............................................................................................................... 41
10.3 Torque for Stainless Steel Screws (A2-70) ................................................................ 48
10.4 Pin Assignment ......................................................................................................... 48
11 Old Equipment Disposal 51
12 EU Declaration of Conformity 53
Page 5
1 About this Document
Downloading Manuals ................................................................................................................... 3
1
About this Document
In this Chapter
Objective and Target Audience of this User Manual ..................................................................... 1
Symbols and Typographic Conventions ......................................................................................... 1
Figures ............................................................................................................................................ 2
Other Applicable Documents ......................................................................................................... 2
1.1 Objective and Target Audience of this User Manual
This user manual contains the necessary information for the intended use of the P-611 (x stands
for the different models (p. 9)).
Basic knowledge of control technology, drive technologies and suitable safety measures is
assumed.
The latest versions of the user manuals are available for download (p. 3) on our website.
1.2 Symbols and Typographic Conventions
The following symbols and typographic conventions are used in this user manual:
NOTICE
CAUTION
Dangerous situation
Failure to comply could lead to minor injury.
Precautionary measures for avoiding.
Dangerous situation
Failure to comply could cause damage to equipment.
Precautionary measures for avoiding.
P-611 Positioning Systems PZ253E Version: 1.1.0 1
INFORMATION
Information for easier handling, tricks, tips, etc.
Page 6
1 About this Document
Action consisting of one or several steps whose sequential order
List item
E-621 Piezo Amplifier/Servo Controller Module
PZ115E User Manual
E-625 Piezo Servo Controller
PZ166E User Manual
E-663 Piezo Amplifier
PZ69E User Manual
E-836 Piezo Amplifier
PZ250E User Manual
PIMikroMove
SM148E Software Manual
Symbol/
Label
1.
2.
p. 5 Cross-reference to page 5
RS-232 Labeling of an operating element on the product (example:
1.3 Figures
For better understandability, the colors, proportions, and degree of detail in illustrations can
deviate from the actual circumstances. Photographic illustrations may also differ and must not
be seen as guaranteed properties.
Meaning
Action consisting of several steps whose sequential order must
be observed
is irrelevant
socket of the RS-232 interface)
Warning signs affixed to the product that refer to detailed
information in this manual.
1.4 Other Applicable Documents
The devices and software tools from PI mentioned in this documentation are described in their
own manuals.
The latest versions of the user manuals are available for download (p. 3) on our website.
Product Document
E-503 Piezo Amplifier Module PZ62E User Manual
E-505 Piezo Amplifier Module
E-610 Piezo Amplifier / Servo Controller (OEM Module) PZ70E User Manual
E-664 NanoCube® Piezo Controller PZ99E User Manual
E-665 Piezo Amplifier / Servo Controller PZ127E User Manual
E-727.x • E-727.xAP Digital Multi-Channel Piezo
Controller
E-727.xF Digital Multi-Channel Piezo Controller
E727T0005 User Manual
P-5xx / P-6xx / P-7xx Piezo Positioning Systems PZ240EK Short Instructions
2 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 7
1 About this Document
If a manual is missing or problems occur with downloading:
1.5 Downloading Manuals
INFORMATION
Contact our customer service department (p. 33).
INFORMATION
For products that are supplied with software (CD in the scope of delivery), access to the
manuals is protected by a password. Protected content is only displayed on the website after
entering the access data.
You need the product CD to get the access data.
For products with CD: Get access data
1. Insert the product CD into the PC drive.
2. Switch to the Manuals directory on the CD.
3. In the Manuals directory, open the Release News (file including releasenews in the file
name).
4. Get the access data for downloading protected content in the "User login for software
download" section of the Release News. Possible methods for getting the access data:
− Link to a page for registering and requesting the access data
− User name and password is specified
5. If the access data needs to be requested via a registration page:
a) Follow the link in the Release News.
b) Enter the required information in the browser window.
c) Click Show login data in the browser window.
d) Note the user name and password shown in the browser window.
Downloading manuals
If you have requested access data for protected contents via a registration page (see above):
Click the links in the browser window to change to the content for your product and log
in using the access data that you received.
P-611 Positioning Systems PZ253E Version: 1.1.0 3
Page 8
1 About this Document
General procedure:
1. Open the website www.pi.ws.
2. If access to the manuals is protected by a password:
a) Click Login.
b) Log in with the user name and password.
3. Click Search.
4. Enter the product number up to the period (e.g., P-611) or the product family (e.g.,
NanoCube®) into the search field.
5. Click Start search or press the Enter key.
6. Open the corresponding product detail page in the list of search results:
a) If necessary: Scroll down the list.
b) If necessary: Click Load more results at the bottom of the list.
c) Click the corresponding product in the list.
7. Click the Downloads tab.
The manuals are shown under Documentation.
8. Click the desired manual and save it to the hard disk of your PC or to a data storage
medium.
4 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 9
2 Safety
Organizational Measures ............................................................................................................... 7
.2S/.20
in two axes horizontally
X, Y
.3S/.3SF/.3O/.3OF
in two axes horizontally and in one axis vertically
X, Y, Z
2
Safety
In this Chapter
Intended Use .................................................................................................................................. 5
General Safety Instructions............................................................................................................ 6
2.1 Intended Use
The P-611 is a laboratory device as defined by DIN EN 61010-1. It is intended to be used in
interior spaces and in an environment which is free of dirt, oil, and lubricants.
Based on its design and realization, the P-611 is intended for fine positioning as well as the fast
and precise motion of small objects. The specifications of the P-611 apply to horizontal
mounting. The motion is performed as follows depending on the model:
Model Motion Axis
.1S/.10 in one axis horizontally X
.XZS/.XZ0 in one axis horizontally and in one axis vertically X, Z
.ZS/.Z0 in one axis vertically Z
Vertical mounting is only possible under certain conditions.
The intended use of the P-611 is only possible in conjunction with suitable electronics (p. 13)
available from PI. The electronics are not included in the scope of delivery of the P-611.
The electronics must provide the required operating voltages. To ensure proper performance of
the servo control system, the electronics must also be able to read out and process the signals
from the position sensors.
P-611 Positioning Systems PZ253E Version: 1.1.0 5
Page 10
2 Safety
2.2 General Safety Instructions
The P-611 is built according to state-of-the-art technology and recognized safety standards.
Improper use can result in personal injury and/or damage to the P-611.
Use the P-611 for its intended purpose only, and only when it is in perfect technical
condition.
Read the user manual.
Eliminate any faults and malfunctions likely to affect safety immediately.
The operator is responsible for the correct installation and operation of the P-611.
The P-611 is driven by piezo actuators. Temperature changes and compressive stresses can
induce charges in piezo actuators. After disconnection from the electronics, piezo actuators can
remain charged for several hours. Touching or short-circuiting the contacts in the connector of
the P-611 can lead to minor injuries from electric shock. The piezo actuators can be destroyed
by an abrupt contraction.
Do not open the P-611.
Discharge the positioner's piezo actuators before installation:
Connect the positioner to the switched-off PI controller, which is equipped with an
internal discharge resistor.
Do not pull the plug connector out of the electronics during operation.
Positioners with D-sub plug connector:
Touching the contacts in the plug connector can lead to an electric shock (max. 130 V DC) and
minor injuries.
Do not touch the contacts in the plug connector.
Secure the plug connector of the positioner with screws against being pulled out of the
controller.
If a protective earth conductor is not or not properly connected, dangerous touch voltages can
occur on the P-611 in the case of malfunction or failure of the system. If touch voltages exist,
touching the P-611 can result in minor injuries from electric shock.
Connect the P-611 to a protective earth conductor (p. 18) before startup.
Do not remove the protective earth conductor during operation.
If the protective earth conductor has to be removed temporarily (e.g., in the case of
modifications), reconnect the P-611 to the protective earth conductor before restarting.
6 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 11
2 Safety
Mechanical forces can damage or misalign the P-611.
Avoid impacts that affect the P-611.
Do not drop the P-611.
Do not exceed the maximum permissible stress and load capacities according to the
specifications (p. 35).
The P-611 is maintenance-free and achieves its positioning accuracy as a result of the optimum
alignment of mechanical components and piezo actuators. Loosened screws cause a loss in
positioning accuracy.
Loosen screws only when instructed in this manual.
Do not open the P-611.
Grip the surfaces indicated on the P-611's base body (p. 15) only.
2.3 Organizational Measures
User manual
Always keep this user manual available with the P-611.
The latest versions of the user manuals are available for download (p. 3) on our
website.
Add all information from the manufacturer to the user manual, for example
supplements or technical notes.
If you give the P-611 to other users, also include this user manual as well as other
relevant information provided by the manufacturer.
Use the device only if the user manual is complete. Missing information due to an
incomplete user manual can result in minor injury and damage to equipment.
Install and operate the P-611 only after you have read and understood this user
manual.
Personnel qualification
The P-611 may only be installed, started, operated, maintained, and cleaned by authorized and
appropriately qualified personnel.
P-611 Positioning Systems PZ253E Version: 1.1.0 7
Page 12
Page 13
3 Product Description
Technical Features ....................................................................................................................... 13
P-611.1S
Linear nanopositioning system, 100 µm, strain gauge sensor
P-611.XZS
XZ nanopositioning system, 100 µm × 100 µm, strain gauge sensors
3
Product Description
In this Chapter
Model Overview ............................................................................................................................. 9
Product View ................................................................................................................................ 10
Product Labeling .......................................................................................................................... 12
Scope of Delivery ......................................................................................................................... 12
Suitable Electronics ...................................................................................................................... 13
Accessories ................................................................................................................................... 13
3.1 Model Overview
The following standard versions of the P-611 are available:
P-611.1: Linear piezo positioning system
Model Description
P-611.10 Linear nanopositioning system, 120 µm, without sensor
P-611.XZ / P-611.2: XZ and XYZ nanopositioner
Model Description
P-611.2S XY nanopositioning system, 100 µm × 100 µm, strain gauge sensors
P-611.20 XY nanopositioning system, 120 µm × 120 µm, without sensor
P-611.XZ0 XZ nanopositioning system, 120 µm × 120 µm, without sensor
P-611 Positioning Systems PZ253E Version: 1.1.0 9
Page 14
3 Product Description
P-611.3: NanoCube® XYZ system
Model Description
P-611.3S NanoCube® XYZ nanopositioning system, 100 µm × 100 µm × 100 µm,
strain gauge sensors
P-611.3SF NanoCube® XYZ nanopositioning system, 100 µm × 100 µm × 100 µm,
strain gauge sensors, integrated fiber holder
P-611.3O NanoCube® XYZ nanopositioning system, 120 µm × 120 µm × 120 µm,
without sensor
P-611.3OF NanoCube® XYZ nanopositioning system, 120 µm × 120 µm × 120 µm,
without sensor, integrated fiber holder
P-611.Z: Piezo Z stage
Model Description
P-611.ZS Vertical nanopositioning stage, 100 µm, strain gauge sensor
P-611.Z0 Vertical nanopositioning stage, 120 µm, without sensor
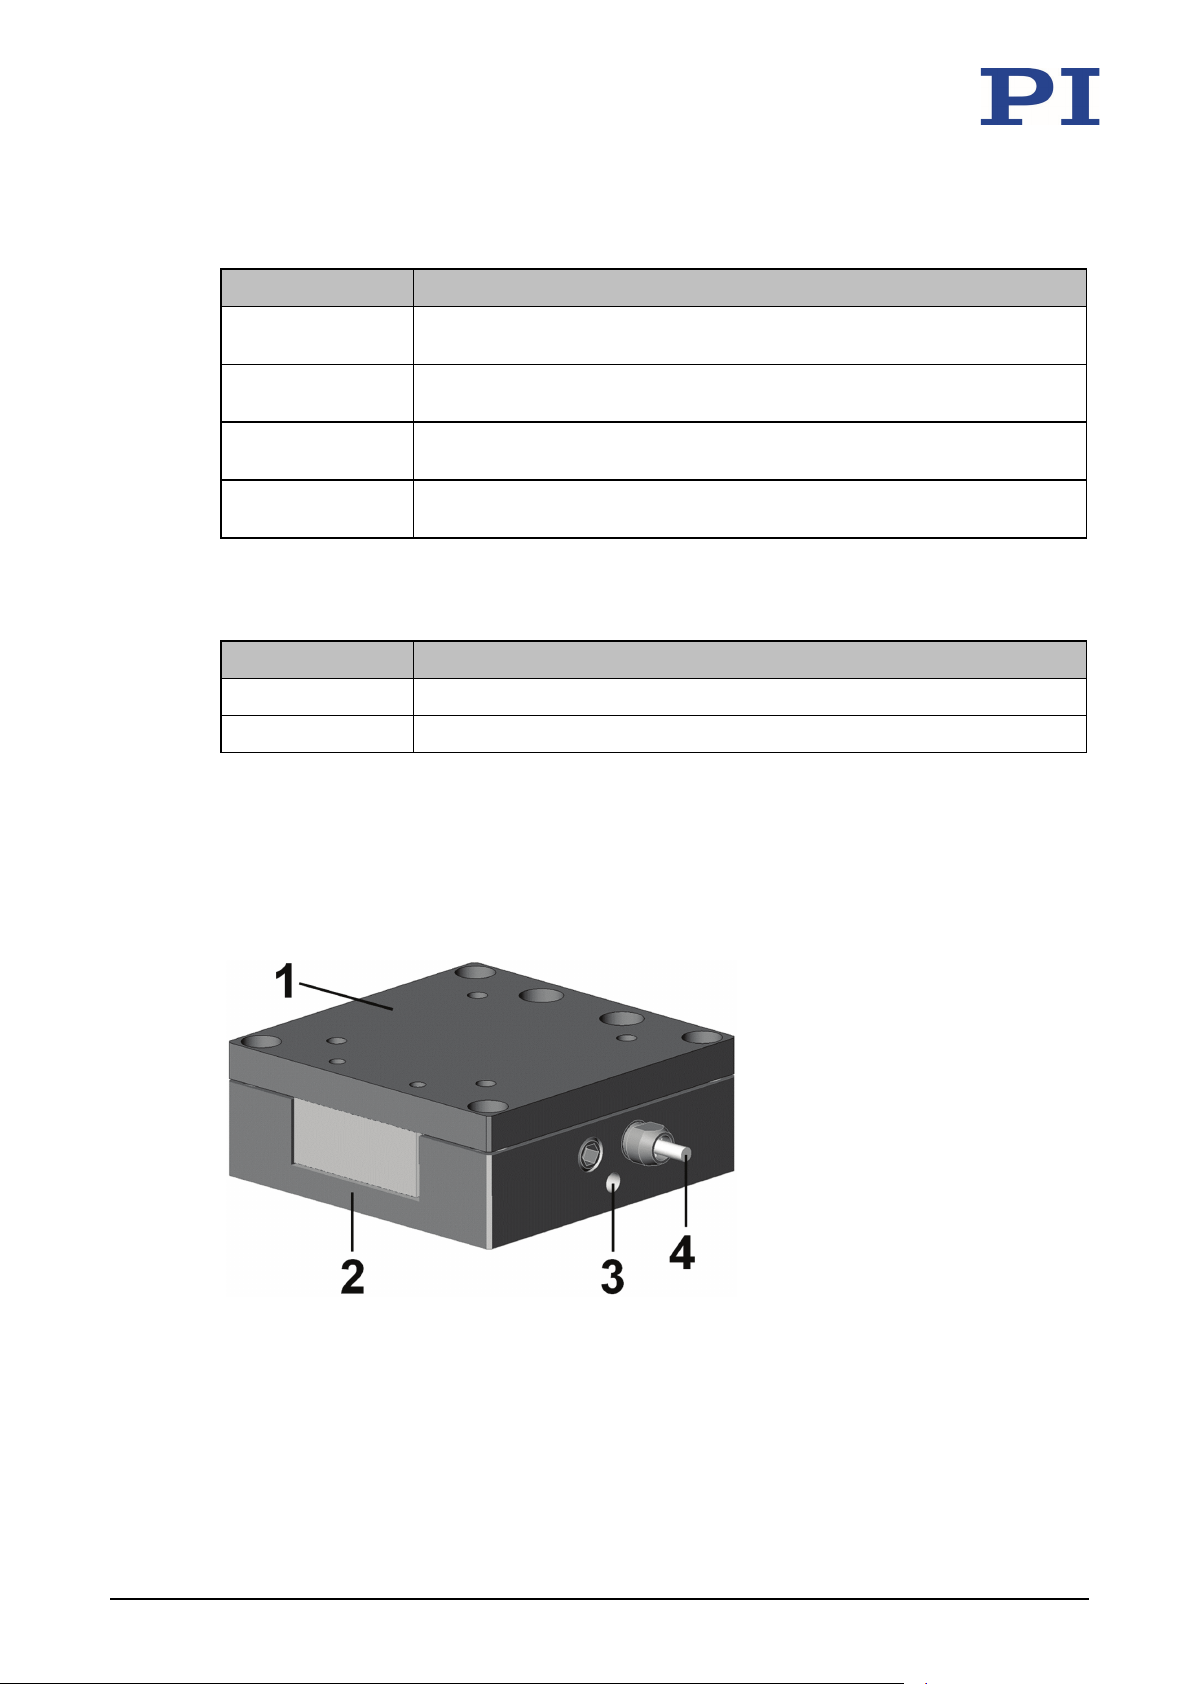
3.2 Product View
The figures serve as examples and can differ from your positioner model.
10 Version: 1.1.0 PZ253E P-611 Positioning Systems
Figure 1: Example of product view
1 Motion platform
2 Base body
3 Protective earth connector
4 Cable exit
Page 15
3 Product Description
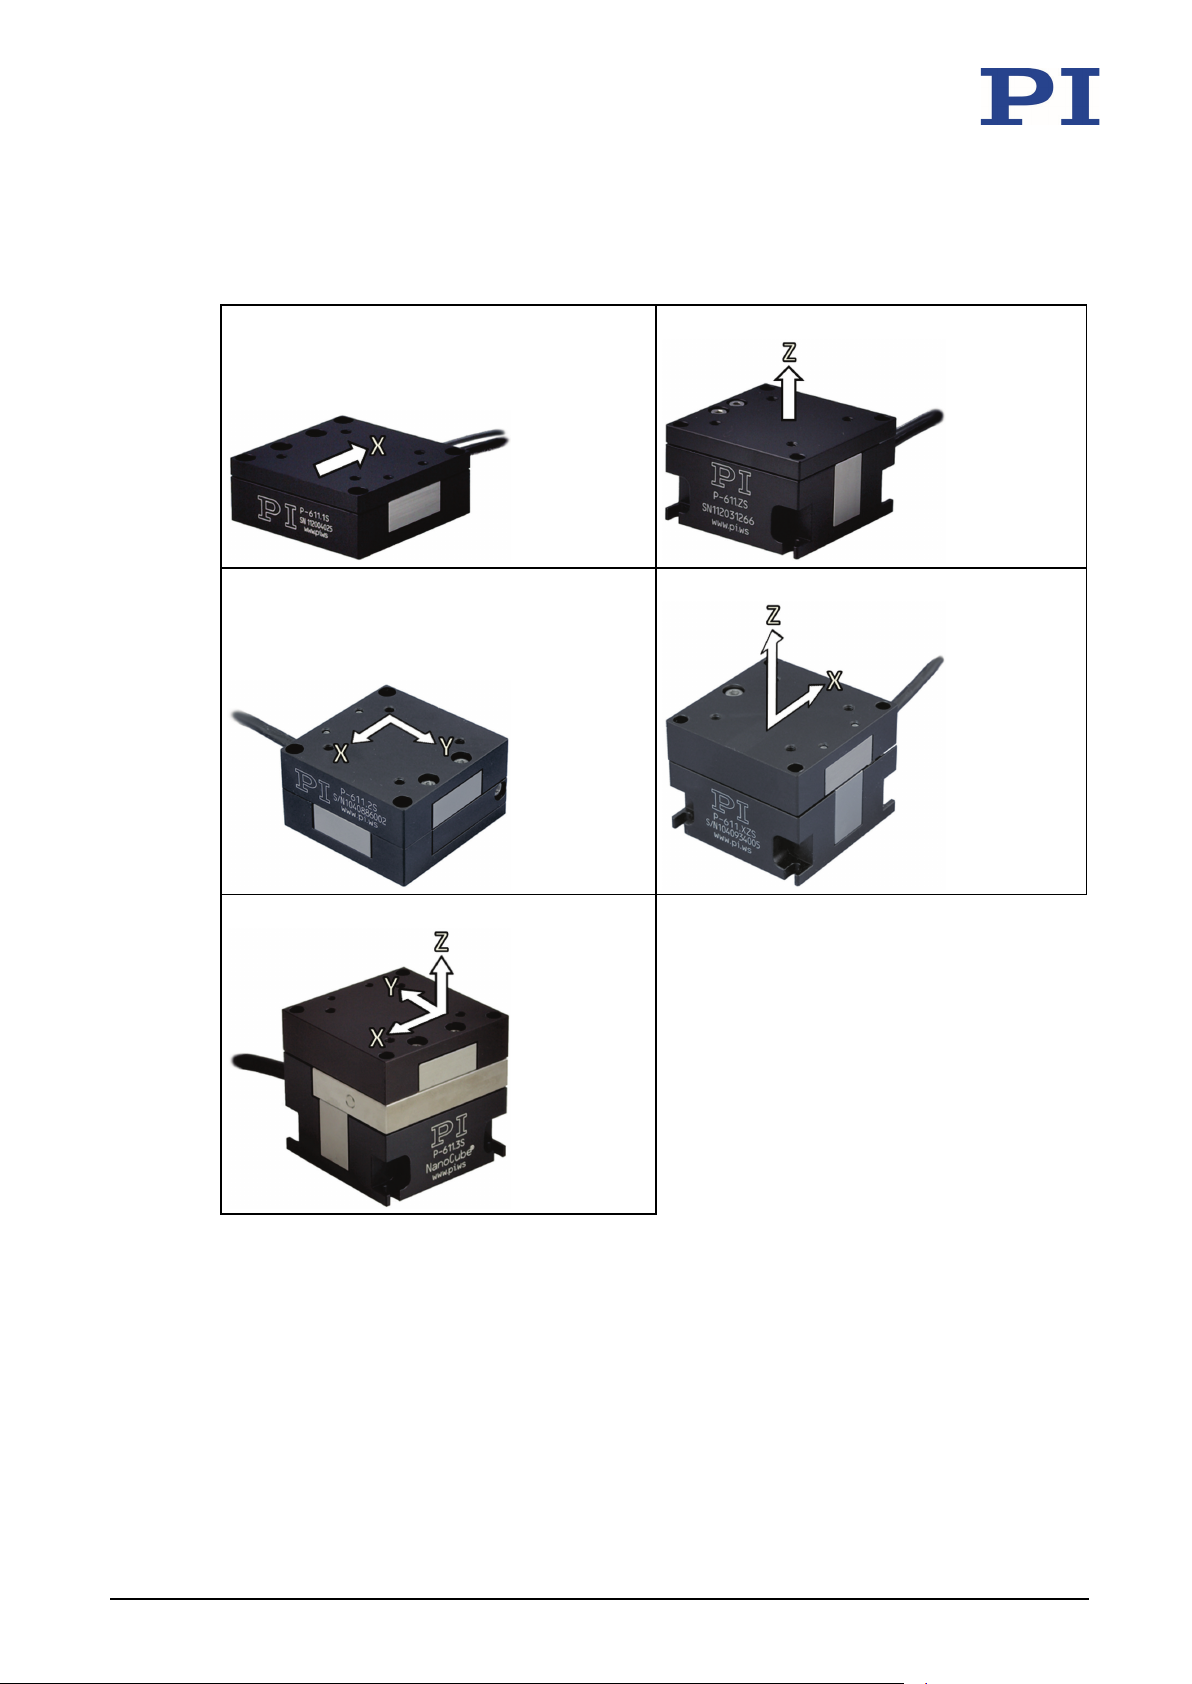
P-611.1x
P-611.Zx
Direction of motion of the P-611
The arrows indicate the positive direction of motion in each case.
P-611.2x P-611.XZx
P-611.3x / P-611.3xF
P-611 Positioning Systems PZ253E Version: 1.1.0 11
Page 16
3 Product Description
P-611
Positioner according to order (p. 9)
000036450
M4 screw set for protective earth, consisting of:
PZ240EK
Short instructions for piezo positioning systems
3.3 Product Labeling
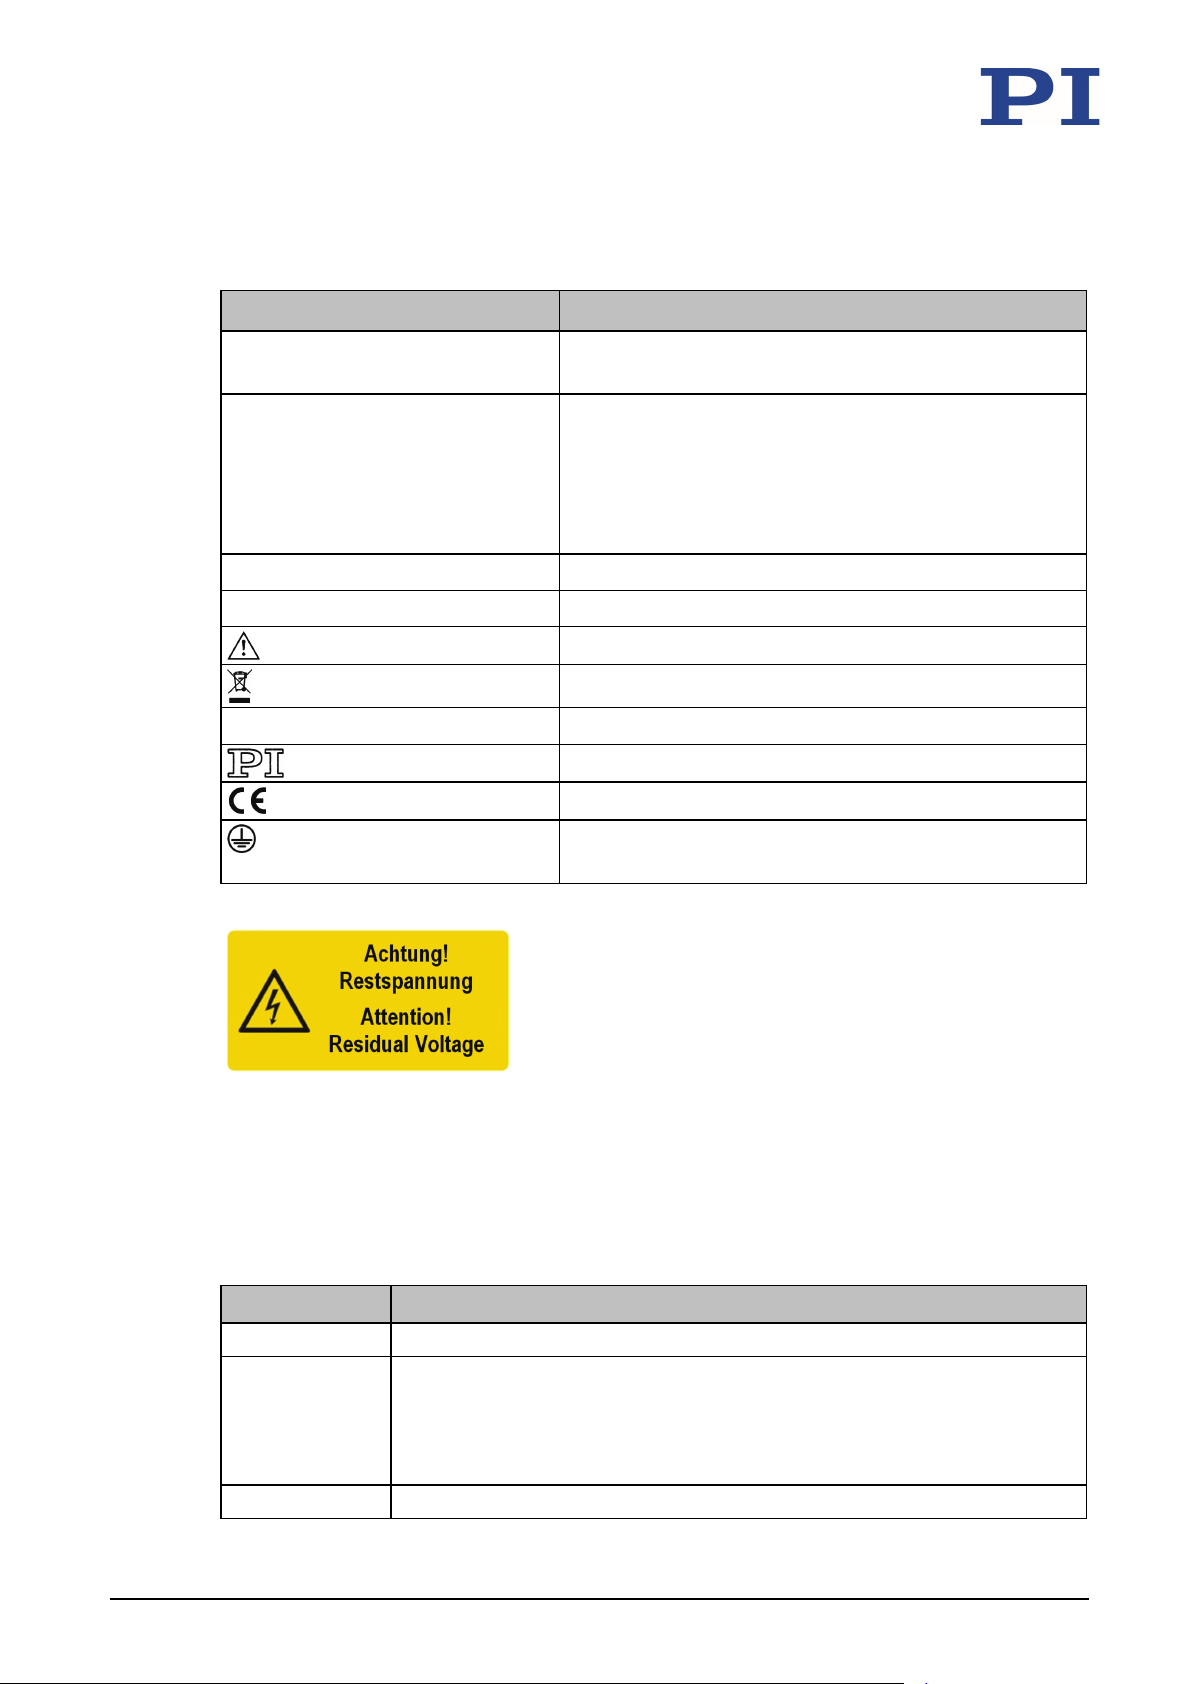
Labeling Description
P-611.XZS Product name (example), the characters following the
123456789 Serial number (example), individual for each P-611
NanoCube® Brand name (.3x and .3xF models only)
Country of origin: Germany Country of origin
period refer to the model
Meaning of each position (from the left):
1 = internal information
2 and 3 = year of manufacture
4 to 9 = consecutive number
Warning sign "Pay attention to the manual!"
WWW.PI.WS Manufacturer's address (website)
Figure 2: "Residual Voltage" warning sign on the connector of the P-611
"Residual Voltage" warning: Risk of electric shock (p. 6) for models with D-sub connector
3.4 Scope of Delivery
Old equipment disposal (p. 51)
Manufacturer's logo
CE conformity mark
Symbol for the protective earth conductor, marks the
protective earth connection of the P-611 (p. 18)
Product number Description
1 flat-head screw with cross recess, M4x8, ISO 7045
2 safety washers
2 flat washers
12 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 17
3 Product Description
E-621 Piezo Amplifier/Servo Controller Module
D-sub 7W2
1
E-727.x • E-727.xAP Digital Multi-Channel Piezo
D-sub 25W3
3
P-895.1LDC
Adapter cable LEMO to D-sub 7W2 (m) for piezo actuator nanopositioning
3.5 Suitable Electronics
You need suitable electronics to operate a P-611. Selecting the device depends on the
application and the connectors available.
Electronics Connector* Channels**
E-505 Piezo Amplifier Module LEMO 1
E-610 Piezo Amplifier / Servo Controller (OEM module) LEMO 1
E-836 Piezo Amplifier LEMO 1
E-503 Piezo Amplifier Module LEMO 3
E-663 Piezo Amplifier LEMO 3
E-625 Piezo Servo Controller D-sub 7W2 1
E-665 Piezo Amplifier / Servo Controller D-sub 7W2 1
E-664 NanoCube® Piezo Controller D-sub 25 3
Controller
E-727.xF Digital Multi-Channel Piezo Controller D-sub 25W3 3
* In some cases, adapter cables (p. 13) are necessary for connecting.
** When using single-channel electronics, each motion axis requires its own individual
electronics.
3.6 Accessories
Adapter cables for models with LEMO plug connectors
Product number Description
systems with capacitive sensors, 1 channel, length: 0.3 m.
P-895.3LDC Adapter cable LEMO to D-sub 25W3 (m) for piezo actuator nanopositioning
systems with capacitive sensors, 3 channels, length: 0.3 m.
To order, contact our customer service department (p. 33).
3.7 Technical Features
3.7.1 PICMA® Piezo Actuators
P-611 positioners are driven by PICMA® piezo actuators. PICMA® actuators have all-ceramic
insulation and their performance and lifetime are therefore far superior to conventional
actuators. The ceramic insulation layer protects the monolithic piezoceramic block against
humidity and failure due to increased leakage current. In this way, an especially high reliability
is achieved even under extreme ambient conditions. In contrast to motorized drives, there are
no rotating parts or friction. The piezo actuators are therefore free of backlash, maintenance,
P-611 Positioning Systems PZ253E Version: 1.1.0 13
and wear.
Page 18
3 Product Description
3.7.2 Flexure Guides
P-611 positioners have flexure guides for friction-free motion and high guiding accuracy.
A flexure guide is an element that is free of static and sliding friction. It is based on the elastic
deformation (bending) of a solid (e.g., steel) and does not have any rolling or sliding parts.
Flexure elements have a high stiffness and load capacity. Flexure guides are maintenance and
wear free. They are 100 % vacuum compatible, function in a wide temperature range and do
not require any lubricants.
3.7.3 Strain Gauge Sensors (SGS)
Strain gauge sensors derive the position information from their expansion. They are attached at
a suitable position in the drivetrain, where they measure the displacement of the positioner's
moving part against the base body. This type of position measuring is indirect and requires
contact, because the position of the motion platform is derived from a measurement on the
lever, guide or piezo stack.
The sensors operate in thermally drift-free full bridge circuitry and therefore ensure optimum
position stability in the nanometer range.
14 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 19
4 Unpacking
xure joints of the P-611 as well
4
Unpacking
NOTICE
Mechanical overload from incorrect handling!
Impermissible mechanical loading of the motion platform as well as certain surfaces of the
P-611 can lead to damage to the piezo actuators, sensors and fle
as to loss of accuracy. In addition, the P-611 can be damaged from tensile forces on the cable
exit and bending of the connecting cable.
Grip the surfaces indicated on the P-611's base body (p. 15) only.
Avoid tensile forces on the cable exit and do not bend the cable.
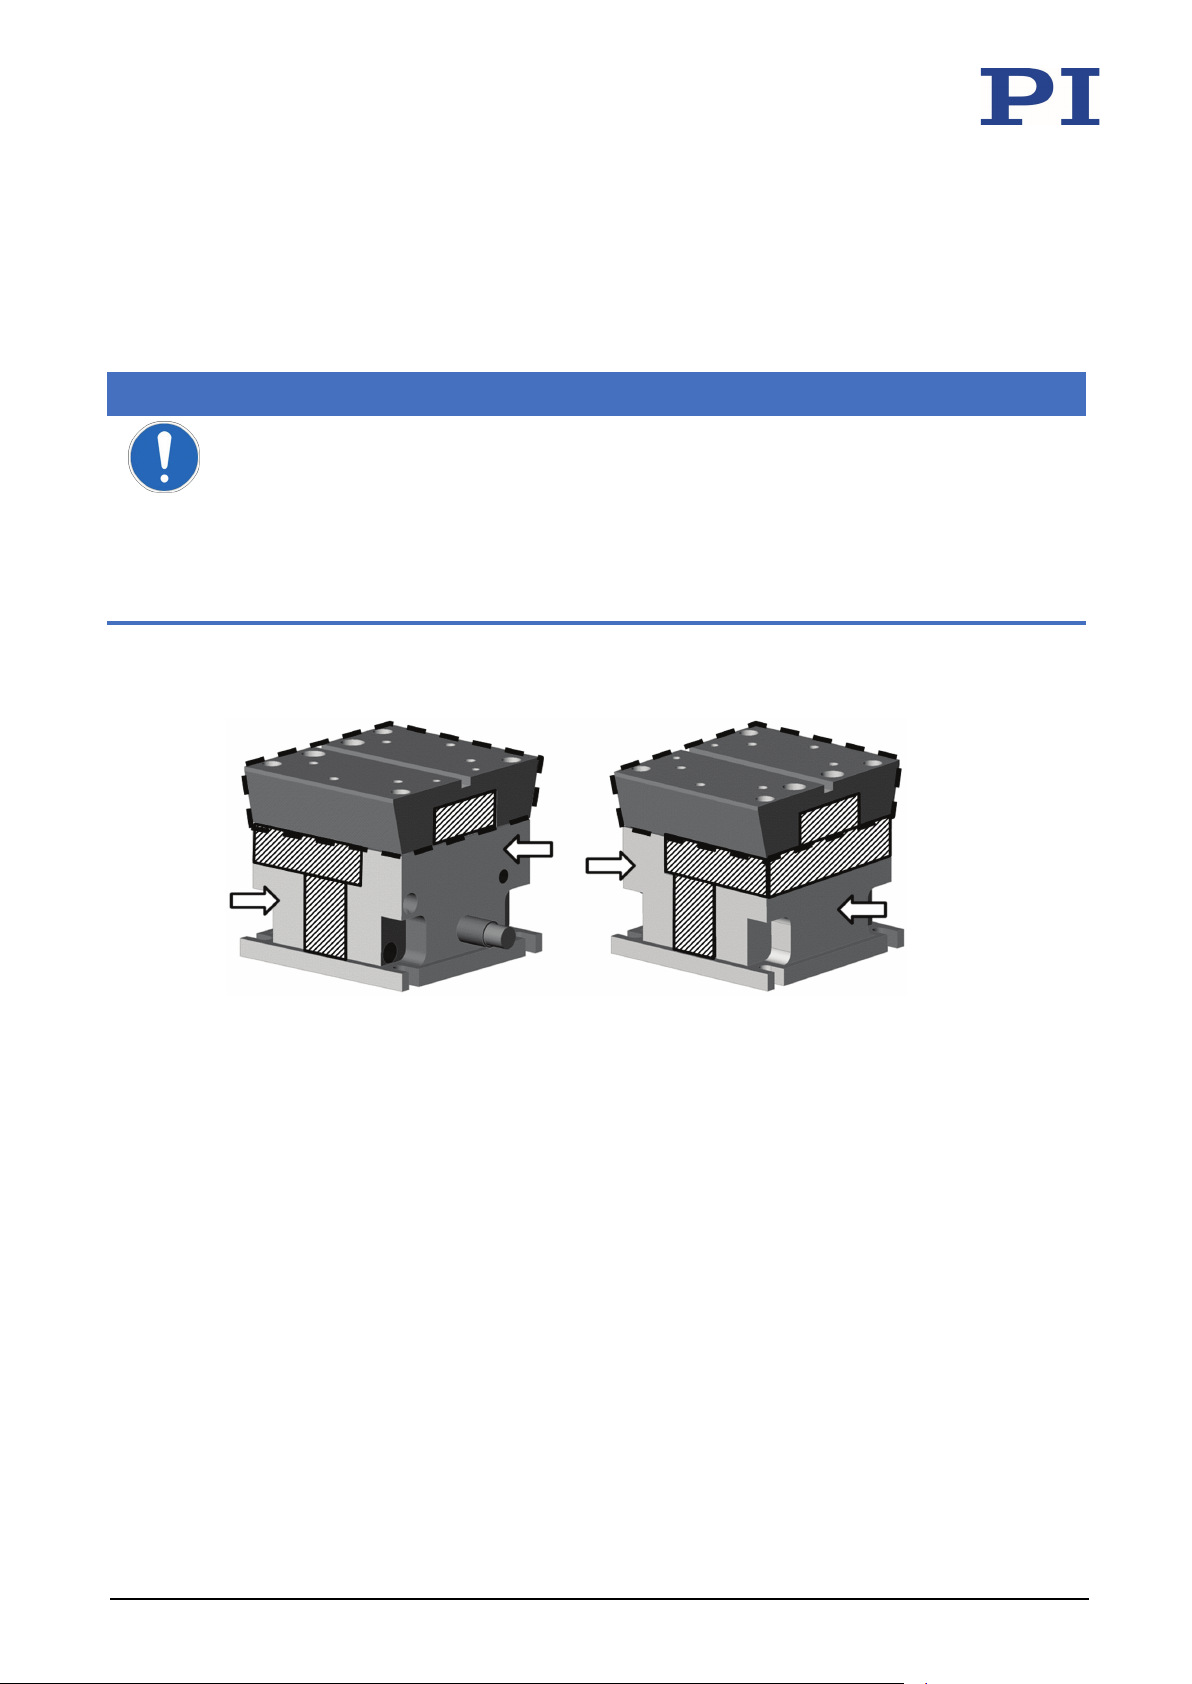
The figure serves as an example and can differ from your positioner model.
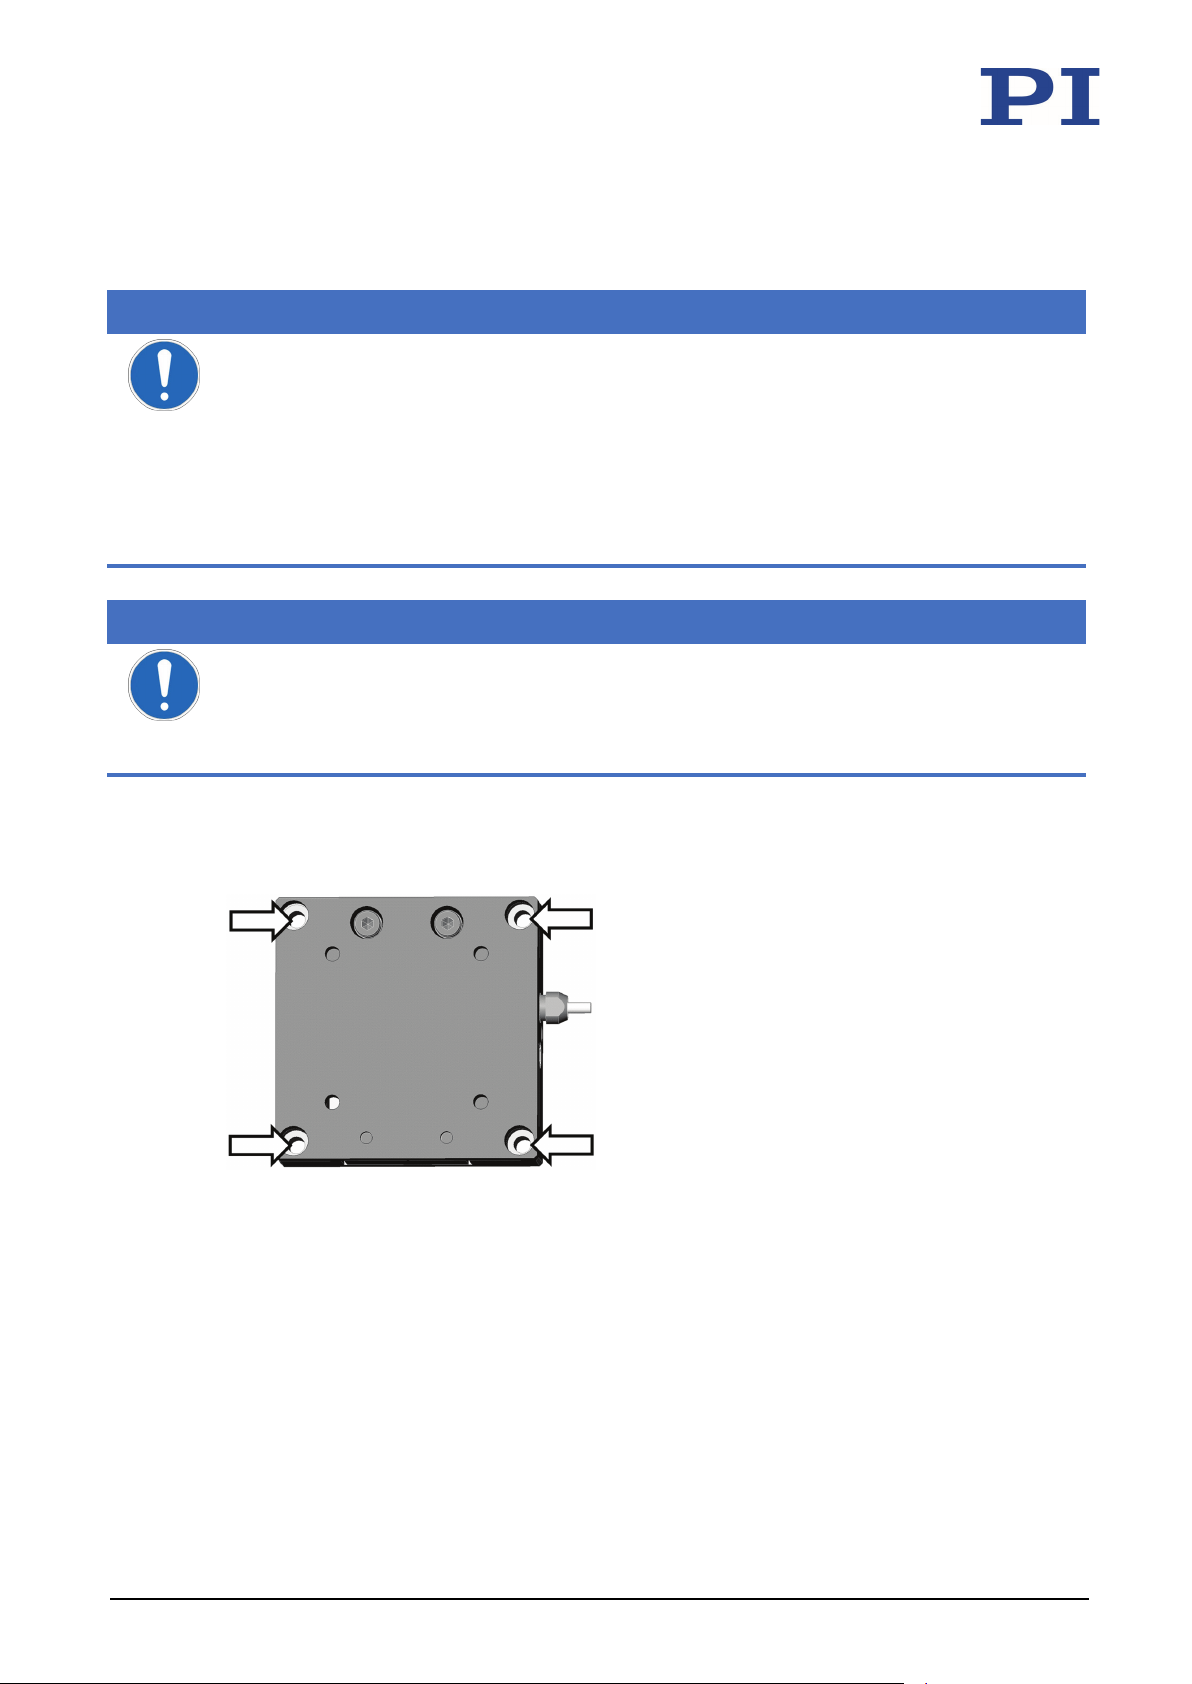
Figure 3: P-611: Holding surfaces to be used on the base body (see arrows)
Areas to be protected against the application of force:
- Motion platform (framed with a dashed line)
- Nonanodized surfaces (crosshatched)
1. Unpack the P-611 with care:
a) Spread the foam packaging apart with one hand.
b) Grip the positioner on the surfaces marked by the arrows.
c) Grip all of the positioner's connecting cables with your other hand.
d) At the same time, remove the positioner and the connecting cables carefully from
the foam packaging.
2. Compare the contents of the shipment with the items listed in the contract and the
delivery note.
3. Inspect the contents for signs of damage. If there is any sign of damage or missing parts,
contact PI immediately.
4. Keep all packaging materials in case the product needs to be returned.
P-611 Positioning Systems PZ253E Version: 1.1.0 15
Page 20
4 Unpacking
16 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 21
5 Installation
Fixing the Load ............................................................................................................................. 22
damage to the piezo actuators, sensors and flexure joints of the P-611 as well
5
Installation
In this Chapter
General Notes on Installation ...................................................................................................... 17
Connecting the P-611 to the Protective Earth Conductor ........................................................... 18
Mounting the P-611 ..................................................................................................................... 20
5.1 General Notes on Installation
CAUTION
Dangerous voltage and residual charge in piezo actuators!
The P-611 is driven by piezo actuators. Temperature changes and compressive stresses can
induce charges in piezo actuators. After disconnection from the electronics, piezo actuators
can remain charged for several hours. Touching or short-circuiting the contacts in the
connector of the P-611 can lead to minor injuries from electric shock. The piezo actuators can
be destroyed by an abrupt contraction.
Do not open the P-611.
Discharge the positioner's piezo actuators before installation:
Connect the positioner to the switched-off PI controller, which is equipped with an internal
discharge resistor.
Do not pull the plug connector out of the electronics during operation.
Positioners with D-sub plug connector:
Touching the contacts in the plug connector can lead to an electric shock (max. 130 V DC) and
minor injuries.
Do not touch the contacts in the plug connector.
Secure the plug connector of the positioner with screws against being pulled out of the
controller.
NOTICE
Mechanical overload from incorrect handling!
Impermissible mechanical loading of the motion platform as well as certain surfaces of the
P-611 can lead to
as to loss of accuracy. In addition, the P-611 can be damaged from tensile forces on the cable
exit and bending of the connecting cable.
Grip the surfaces indicated on the P-611's base body (p. 15) only.
Avoid tensile forces on the cable exit and do not bend the cable.
P-611 Positioning Systems PZ253E Version: 1.1.0 17
Page 22
5 Installation
Extension cables can reduce the positioning accuracy of the P-611 or affect sensor processing
In the case of P-611 positioners with D-sub connectors, ground loops can occur when the
NOTICE
Damage due to unsuitable cables!
Unsuitable cables can damage the P-611 and the electronics.
Use cables provided by PI only to connect the P-611 to the electronics.
NOTICE
Damage due to improper mounting!
Improper mounting of the P-611 or incorrectly mounted parts can damage the P-611.
Mount the P-611 and the loads only onto the mounting fixtures (holes) intended for this
purpose.
NOTICE
Damage due to incorrectly tightened screws!
Incorrectly tightened screws can cause damage.
Pay attention to the torque range (p. 48) specified for the screws used during installation.
INFORMATION
by the electronics.
Do not use extension cables. If you need longer cables, contact our customer service
department (p. 33).
5.2 Connecting the P-611 to the Protective Earth Conductor
INFORMATION
positioner is grounded via its protective earth connection as well as by the shield of the
connecting cable for the electronics.
If a ground loop occurs, contact our customer service department (p. 33).
INFORMATION
Pay attention to the applicable standards for connecting the protective earth conductor.
The P-611 has an M4 hole for attaching the protective earth conductor . This hole is marked
with the symbol for the protective earth conductor
. For the exact position of the hole, see
"Dimensions" (p. 41).
18 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 23
5 Installation
Requirements
You have read and understood the general notes on installation (p. 17).
The positioner is not connected to the electronics.
Tools and accessories
Suitable protective earth conductor: Cable cross section ≥ 0.75 mm2
M4 protective earth screw set (p. 12) supplied for connecting the protective earth
conductor
Suitable screwdriver
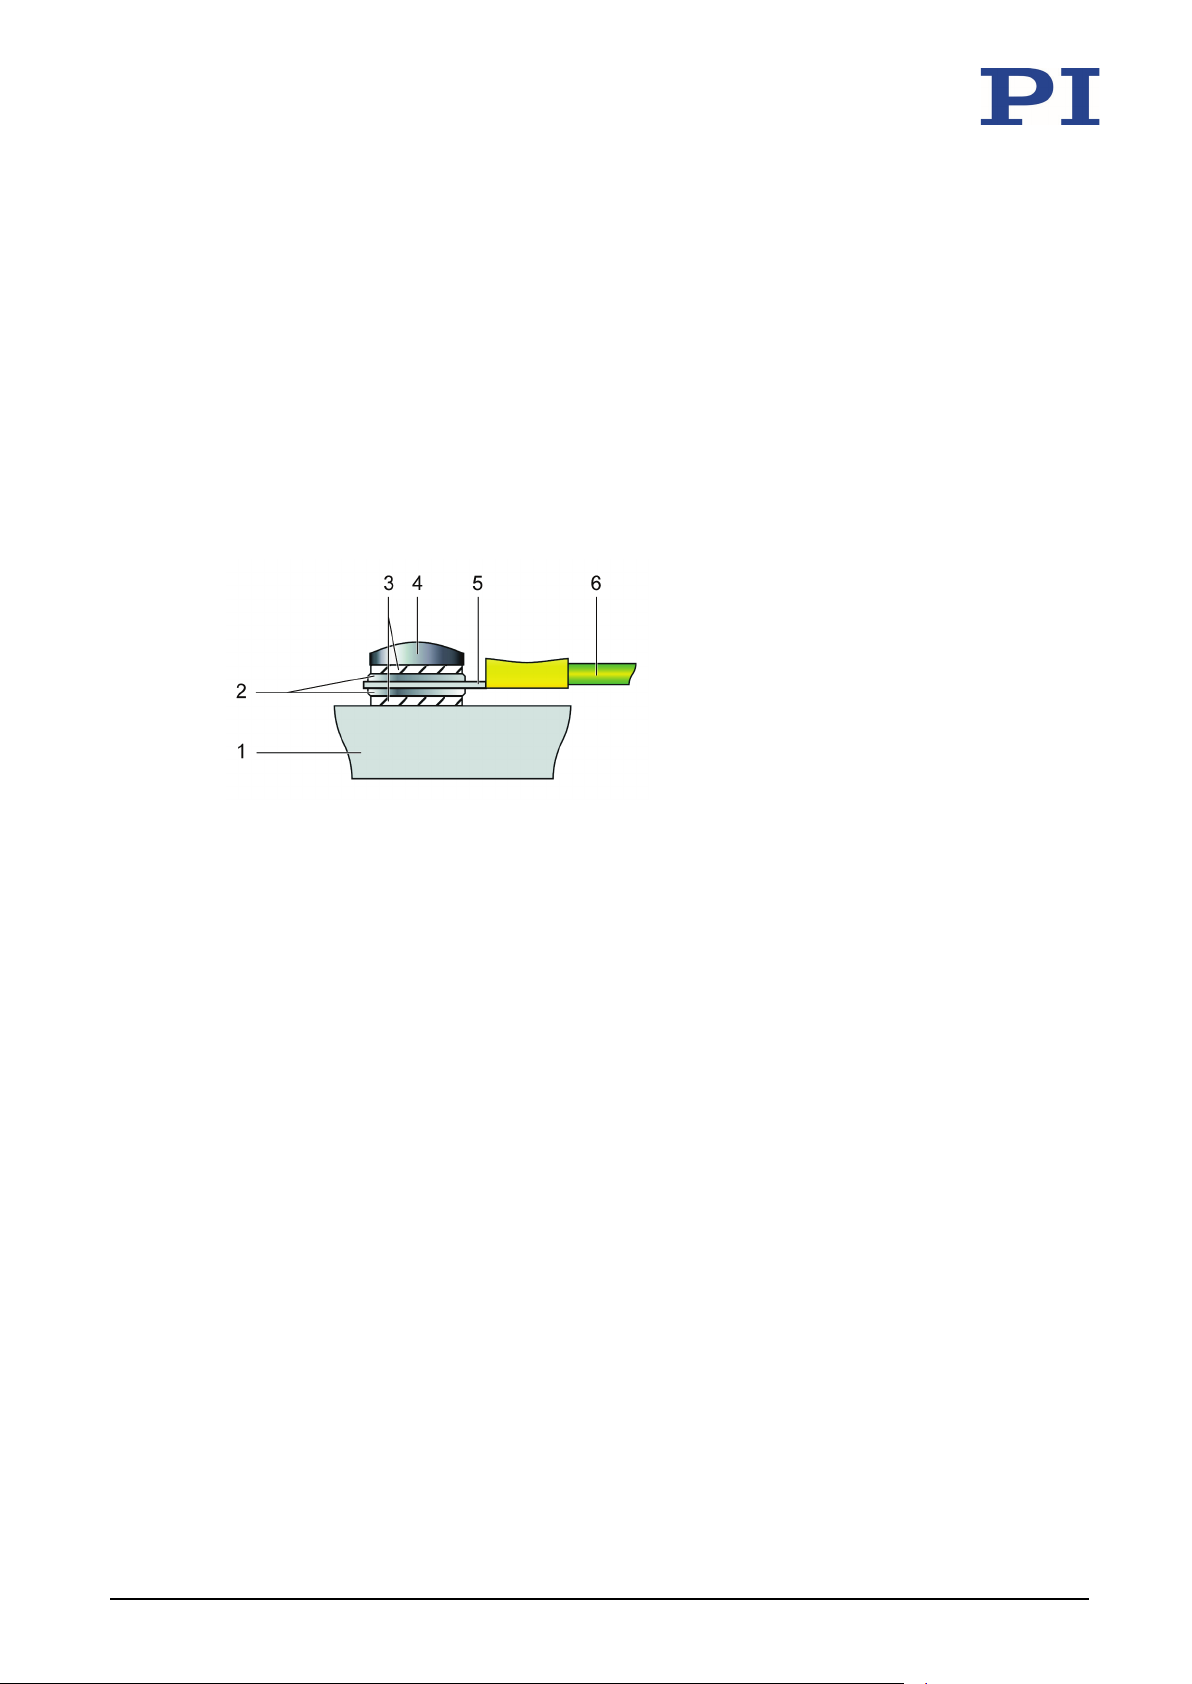
Figure 4: Connecting the protective earth conductor (profile view)
1 Base body of the P-611
2 Flat washer
3 Safety washer
4 Screw
5 Cable lug
6 Protective earth conductor
Connecting the P-611 to the protective earth conductor
1. If necessary, attach a suitable cable lug to the protective earth conductor.
2. Use the M4 screw (together with the washers and self-locking washers) to affix the
cable lug of the protective earth conductor to the protective earth connection of the
P-611 as shown in the profile view.
3. Tighten the M4 screw with a torque of 1.2 Nm to 1.5 Nm.
4. Make sure that the contact resistance at all connection points relevant for connecting
the protective earth conductor is <0.1 Ω at 25 A.
P-611 Positioning Systems PZ253E Version: 1.1.0 19
Page 24
5 Installation
5.3 Mounting the P-611
NOTICE
Warping of the P-611 when mounted on uneven surfaces!
The P-611 could warp if mounted on an uneven surface. Warping reduces the accuracy.
Mount the P-611 onto an even surface. The recommended flatness of the surface is
≤20 µm.
For applications with large temperature changes:
Mount the P-611 only onto surfaces that have the same or similar thermal expansion
properties as the P-611.
NOTICE
Tensile stress on piezo actuator with vertical mounting!
When the positioner is mounted vertically, certain alignments can cause tensile stress, which
reduces the preload and destroys the piezo actuator.
If you want to mount the P-611 vertically, contact our customer service department (p. 33
The following figures serve as examples and can differ from your positioner model.
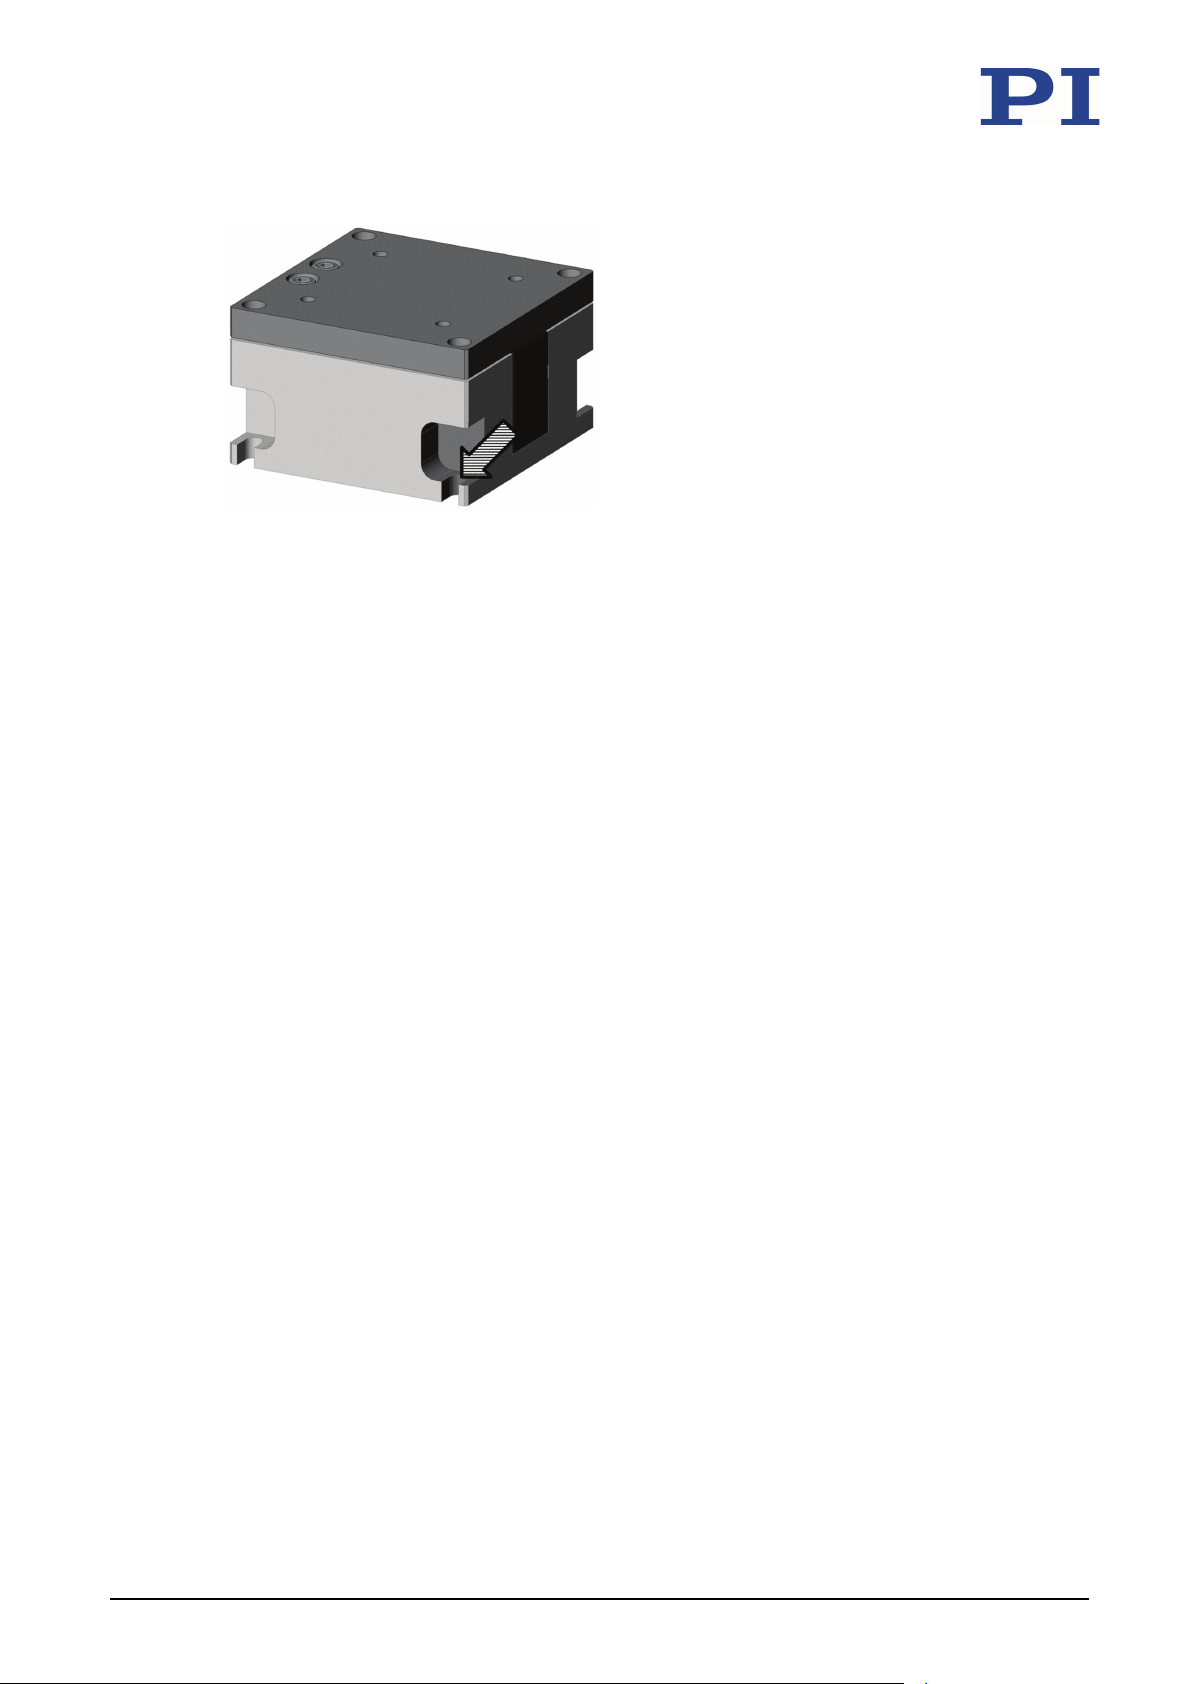
Figure 5: P-611.1x and .2x: Holes for mounting the positioner onto an underlying surface
Number of mounting holes:
P-611.1x: 4
P-611.2x: 3
).
20 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 25
5 Installation
Figure 6: P-611.XZx, .3x, .3xF, and .Zx: One of four recesses in the base body for mounting the
positioner onto an underlying surface
Requirements
You have read and understood the general notes on installation (p. 17).
Tools and accessories
When mounting a P-611.2x:
− 3 screws of suitable size and length (p. 41)
When mounting other models of the P-611:
− 4 screws of suitable size and length (p. 41)
Suitable screwdriver
Mounting the P-611
1. Position the P-611 on a flat underlying surface.
2. Insert the screws:
When mounting a P-611.1x or .2x:
− Insert the screws from above into the countersunk holes in the base body of the
P-611.
When mounting a P-611.XZx, .3x, .3xF or .Zx:
− Insert the screws into the recesses in the base body of the P-611 from the side.
P-611 Positioning Systems PZ253E Version: 1.1.0 21
3. Tighten the screws. Pay attention to the specified torque range (p. 48) while doing so.
Page 26
5 Installation
5.4 Fixing the Load
NOTICE
Mechanical overload due to high torques and high loads!
When affixing the load, high torques and high loads can overload the motion platform of the
P-611. Mechanical overload can cause damage to the piezo actuators, sensors, and flexures of
the P-611 and lead to loss in accuracy.
Avoid torques >50 Ncm on the motion platform.
Do not exceed the maximum permissible stress and load capacities according to the
specifications (p. 35).
Pay attention to the torque range (p. 48) specified for the screws used during installation.
NOTICE
Warping of the P-611 when fixing loads with an uneven contact surface!
Fixing loads to an uneven contact surface could warp the P-611. Warping reduces the accuracy.
Only fix loads on the P-611 whose contact surface with the motion platform of the P-611
has a flatness of at least 20 μm.
For applications with large temperature changes:
Only fix loads to the P-611 that have the same or similar thermal expansion properties as
the P-611.
NOTICE
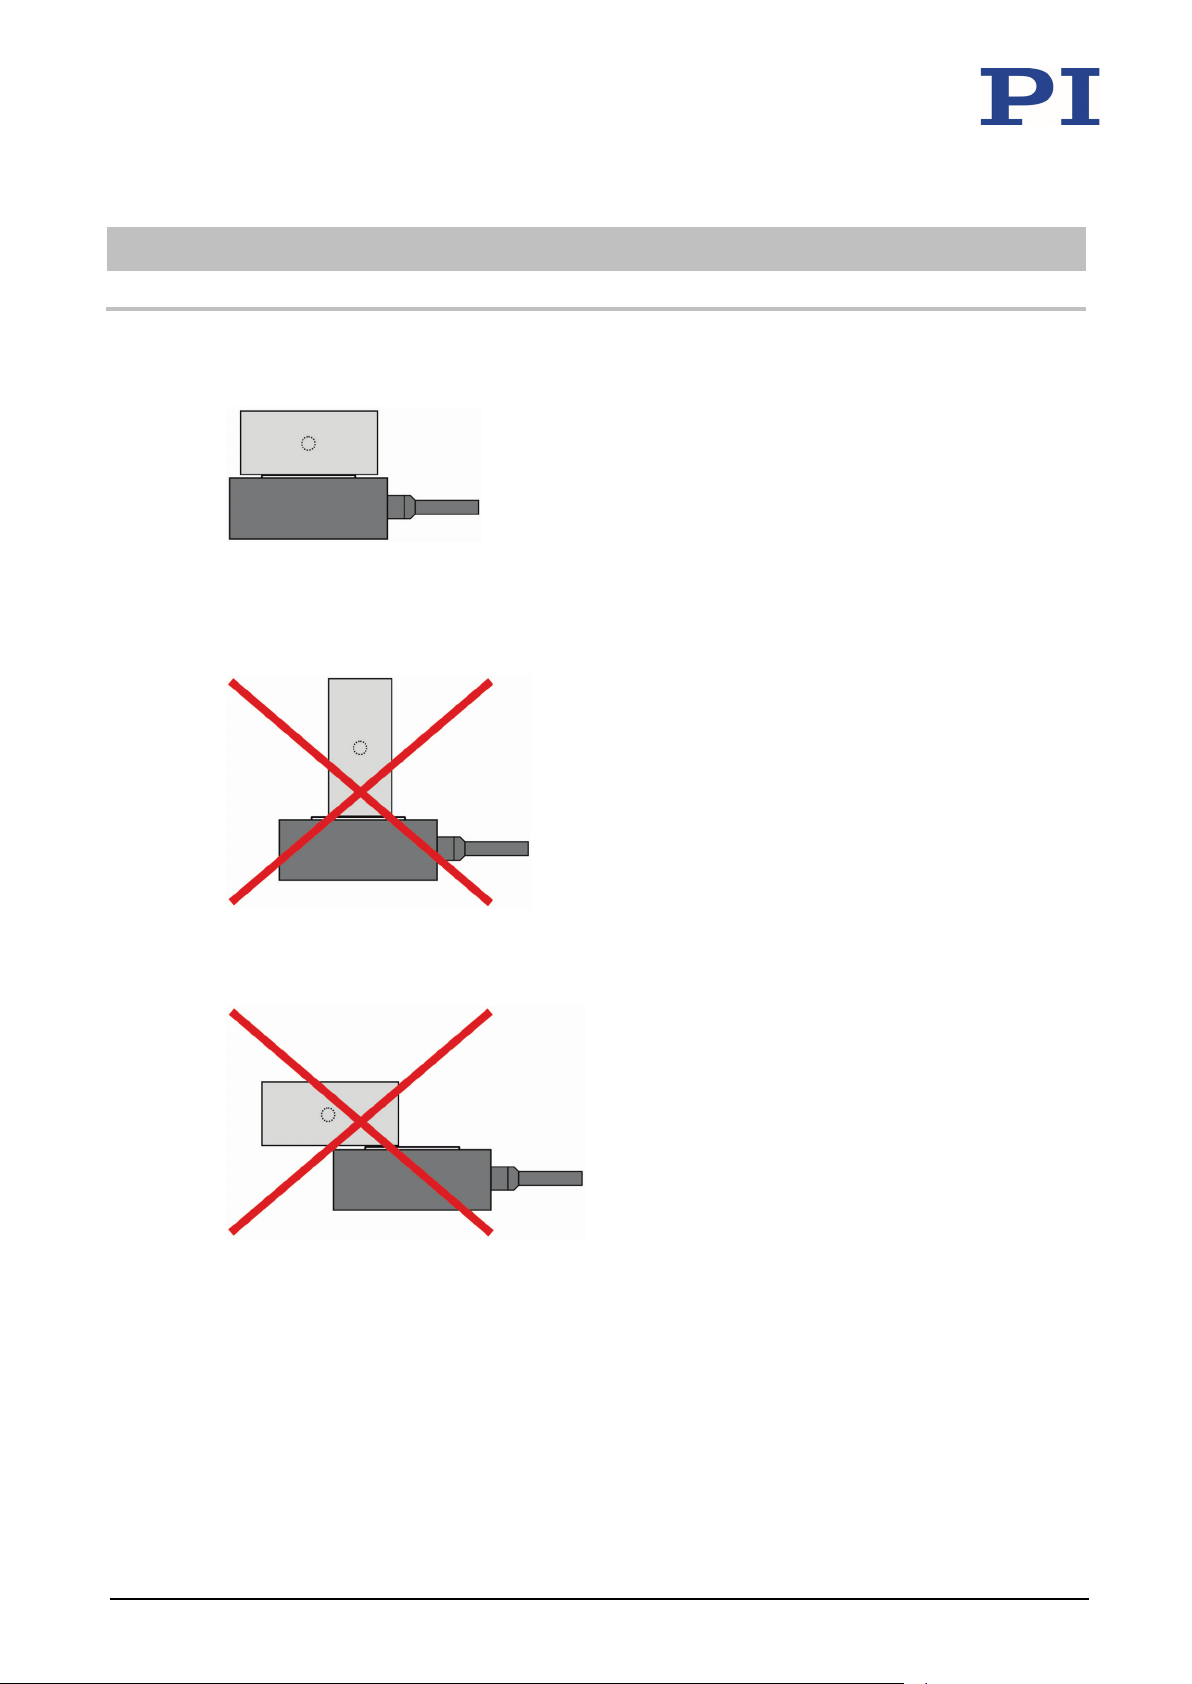
Center of load at unsuitable position!
If the center of load is located too far away from the center of the motion platform (e.g., tall
loads and unwanted lever effect), the P-611 can be damaged by high strain on the flexure
guides, high torques, and oscillation, especially when operated dynamically.
If the center of the load to be affixed is too far above or to the side of the motion platform,
adjust the controller settings before startup or contact our customer service department
(p. 33).
NOTICE
Excessively long screws!
The P-611 can be damaged by excessively long screws.
Note the depth of the mounting holes in the motion platform (p. 41).
Use screws of the correct length for the respective mounting holes only.
22 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 27
5 Installation
INFORMATION
Positive direction of axis motion is specified in the product view (p. 10).
Center of load at the optimum position:
Figure 7: Example of an optimally placed load
Center of load at an unsuitable position:
Figure 8: Tall load and center of load too far above the motion platform
Figure 9: Unwanted lever effect and center of load on the side of the motion platform
Requirements
You have read and understood the general notes on installation (p. 17).
The P-611 is not connected to the electronics.
P-611 Positioning Systems PZ253E Version: 1.1.0 23
Page 28
5 Installation
Tools and accessories
Screws of suitable size and length (p. 41)
Suitable tools
Fixing the load
Fix loads only by inserting suitable screws into the threaded holes (p. 41) provided.
Pay attention to the torque range (p. 48) specified for the screws, and avoid torques
>50 Ncm on the motion platform.
Fix the load so that its load center is in the middle of the motion platform.
24 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 29
6 Startup and Operation
Discharging the P-611 .................................................................................................................. 27
When the P-611 is not used but the electronics remain switched on to ensure temperature
6
Startup and Operation
In this Chapter
General Notes on Startup and Operation .................................................................................... 25
Operating the P-611 ..................................................................................................................... 26
6.1 General Notes on Startup and Operation
CAUTION
Risk of electric shock if the protective earth conductor is not connected!
If a protective earth conductor is not or not properly connected, dangerous touch voltages can
occur on the P-611 in the case of malfunction or failure of the system. If touch voltages exist,
touching the P-611 can result in minor injuries from electric shock.
Connect the P-611 to a protective earth conductor (p. 18) before startup.
Do not remove the protective earth conductor during operation.
If the protective earth conductor has to be removed temporarily (e.g., in the case of
modifications), reconnect the P-611 to the protective earth conductor before restarting.
NOTICE
Destruction of the piezo actuator due to electric flashovers!
Using the P-611 in environments that increase the electrical conductivity can lead to the
destruction of the piezo actuator by electric flashovers. Electric flashovers can be caused by
moisture, high humidity, liquids, and conductive materials (e.g., metal dust). In addition,
electric flashovers can also occur in certain air pressure ranges due to the increased
conductivity of the air.
Avoid operating the P-611 in environments that can increase the electric conductivity.
Operate the P-611 only within the permissible ambient conditions and classifications
(p. 40).
NOTICE
Reduced lifetime due to permanently high voltage!
Applying a high static voltage to piezo actuators continuously reduces the lifetime of the piezo
ceramic.
stability, discharge the P-611 (p. 27).
P-611 Positioning Systems PZ253E Version: 1.1.0 25
Page 30
6 Startup and Operation
NOTICE
Operating voltage too high or incorrectly connected!
Operating voltages that are too high or incorrectly connected can cause damage to the P-611.
Operate the P-611 only with controllers/drivers and original accessories from PI.
Do not exceed the operating voltage range (p. 39) for which the P-611 is specified.
Operate the P-611 only when the operating voltage is properly connected; see "Pin
Assignment" (p. 48).
NOTICE
Uncontrolled oscillation!
Oscillation can cause irreparable damage to the P-611. Oscillation is indicated by a humming
noise and can be caused by the following:
A change in the load and/or dynamics requires the servo control parameters to be
adjusted.
The P-611 is operated near to its resonant frequency.
If you notice oscillation:
In closed-loop operation, switch off the servo mode immediately.
In open-loop operation, stop the P-611 immediately.
INFORMATION
Positive direction of axis motion is specified in the product view (p. 10).
INFORMATION
Sound and vibration (e.g., footfall, knocks) can be transmitted to the P-611 and can affect its
performance with regard to position stability.
Avoid sound and vibration while the P-611 is being operated.
6.2 Operating the P-611
Follow the instructions in the manual for the electronics (p. 13) used for startup and
operation of the P-611.
26 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 31
6 Startup and Operation
6.3 Discharging the P-611
The P-611 must be discharged in the following cases:
Before installation
If the P-611 is not used and the controller remains switched on to ensure temperature
stability
Before demounting (e.g., before cleaning and transporting the P-611 and for
modifications)
The P-611 is discharged via the internal discharge resistor of the controller from PI.
Discharging a positioner connected to the controller
In closed-loop operation:
1. Switch off the servo mode on the controller.
2. Set the piezo voltage to 0 V on the controller.
In open-loop operation:
Set the piezo voltage to 0 V on the controller.
Discharging a positioner not connected to the controller
Connect the positioner to the switched-off controller from PI.
P-611 Positioning Systems PZ253E Version: 1.1.0 27
Page 32
Page 33
7 Maintenance
Cleaning the P-611 ....................................................................................................................... 29
7
Maintenance
In this Chapter
General Notes on Maintenance ................................................................................................... 29
7.1 General Notes on Maintenance
NOTICE
Misalignment due to loosening screws!
The P-611 is maintenance-free and achieves its positioning accuracy as a result of the optimum
alignment of mechanical components and piezo actuators. Loosened screws cause a loss in
positioning accuracy.
Loosen screws only when instructed in this manual.
Do not open the P-611.
7.2 Cleaning the P-611
NOTICE
Damage from ultrasonic cleaning!
Ultrasonic cleaning can damage the P-611.
Do not do any ultrasonic cleaning.
Requirements
You have discharged the piezo actuators of the P-611 (p. 27).
You have disconnected the P-611 from the electronics.
Cleaning the P-611
Clean the surfaces of the P-611 with a cloth dampened with a mild cleanser or
disinfectant (e.g., isopropyl alcohol).
P-611 Positioning Systems PZ253E Version: 1.1.0 29
Page 34
Page 35
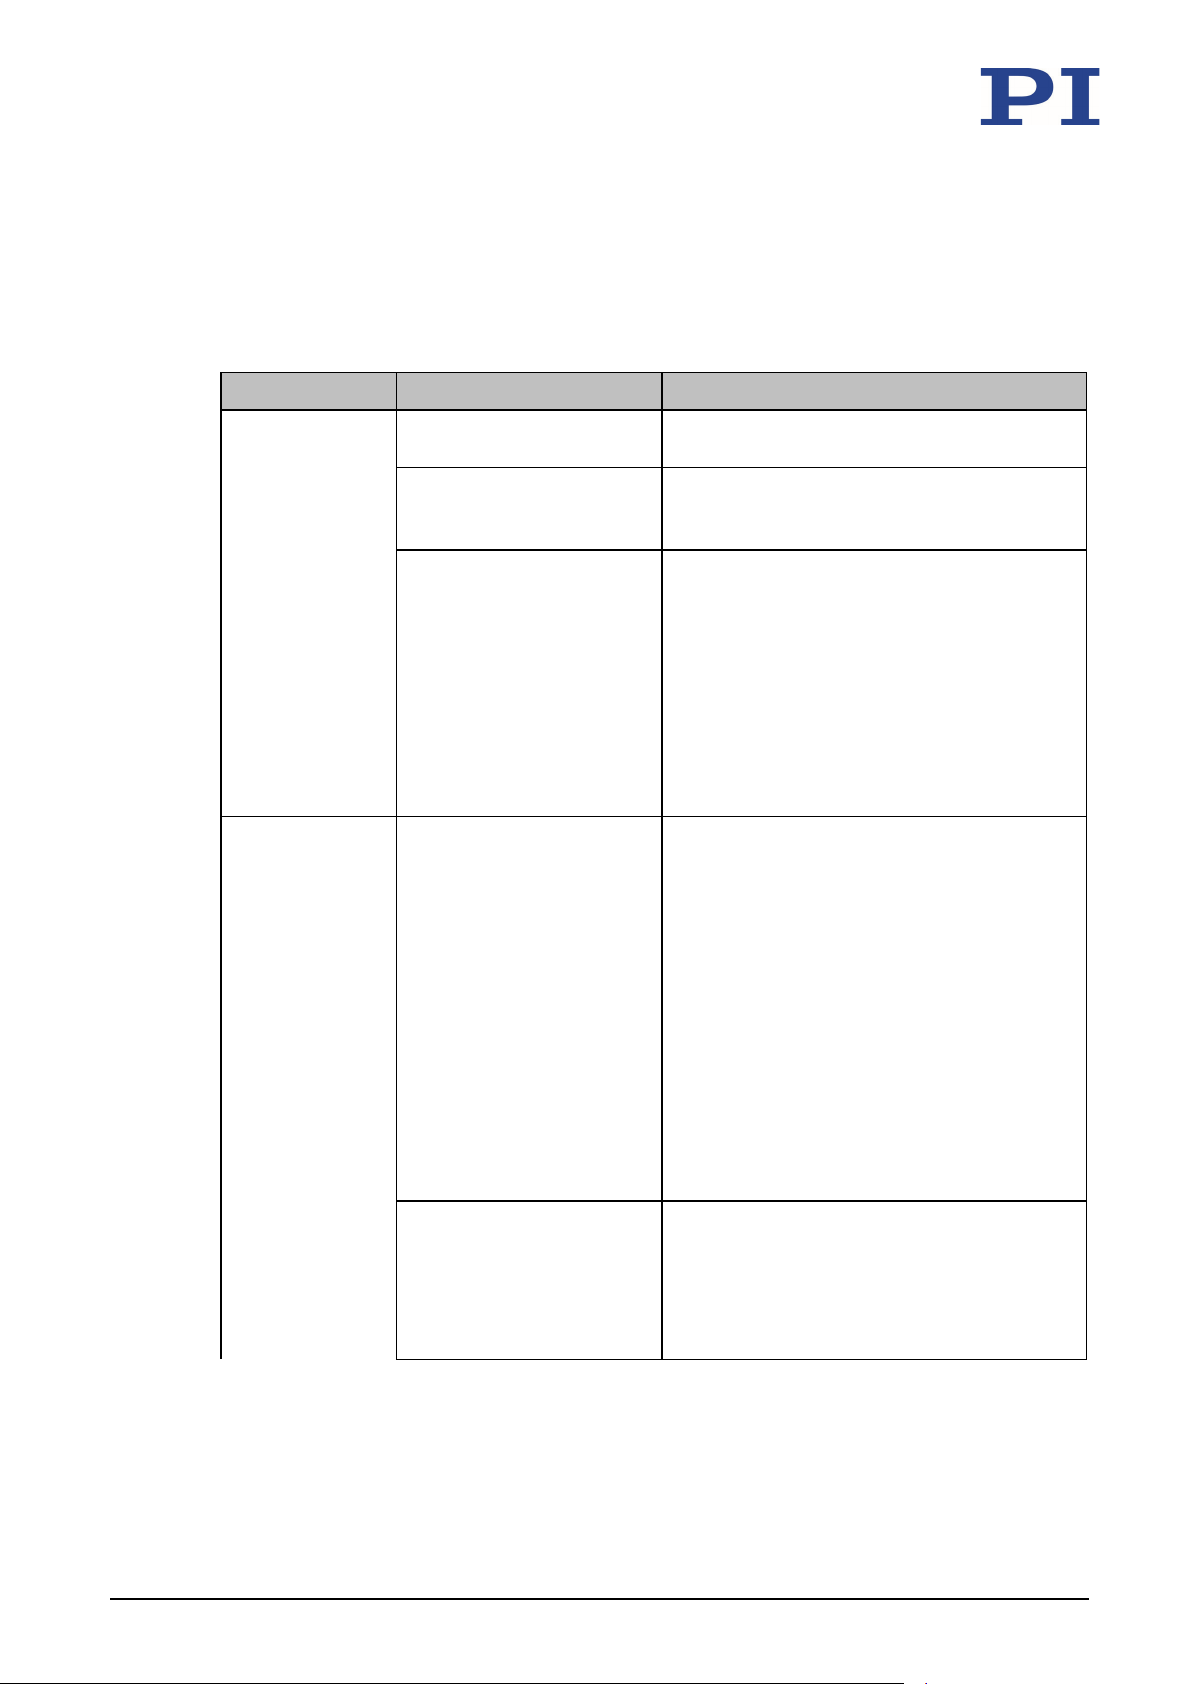
8 Troubleshooting
P-611 or controller has
It is necessary to recalibrate the axis
8
Troubleshooting
Problem Possible causes Solution
No or limited
motion
Cable not connected
correctly
Excessive load Do not exceed the maximum permissible
Zero shift of the sensor for
the following reasons:
Load in direction of
motion
Ambient/operating
temperature of the
positioner is far above
or below the calibration
temperature (21 °C to
24 °C)
Reduced accuracy The base body or the
motion platform is warped
Check the cable connections.
stress and load capacities according to
the specifications (p.
Adjust the zero-point of the sensor (see
controller manual).
Mount the P-611 onto surfaces with the
following characteristics only:
− Flatness of at least 20 μm
− The thermal expansion
properties are similar to those of the
P-611 (e.g., surfaces made of
aluminum).
Mount loads onto the P-611 with the
following characteristics only:
− The contact surface of the load has a
flatness of at least 20 μm.
− The thermal expansion
properties are similar to those of the
P-611 (e.g., loads made of aluminum).
35).
P-611 Positioning Systems PZ253E Version: 1.1.0 31
been replaced
displacement after replacing the P-611 or
controller.
Recalibrate the axis displacement (see
controller manual) or contact our
customer service department (p. 33).
Page 36
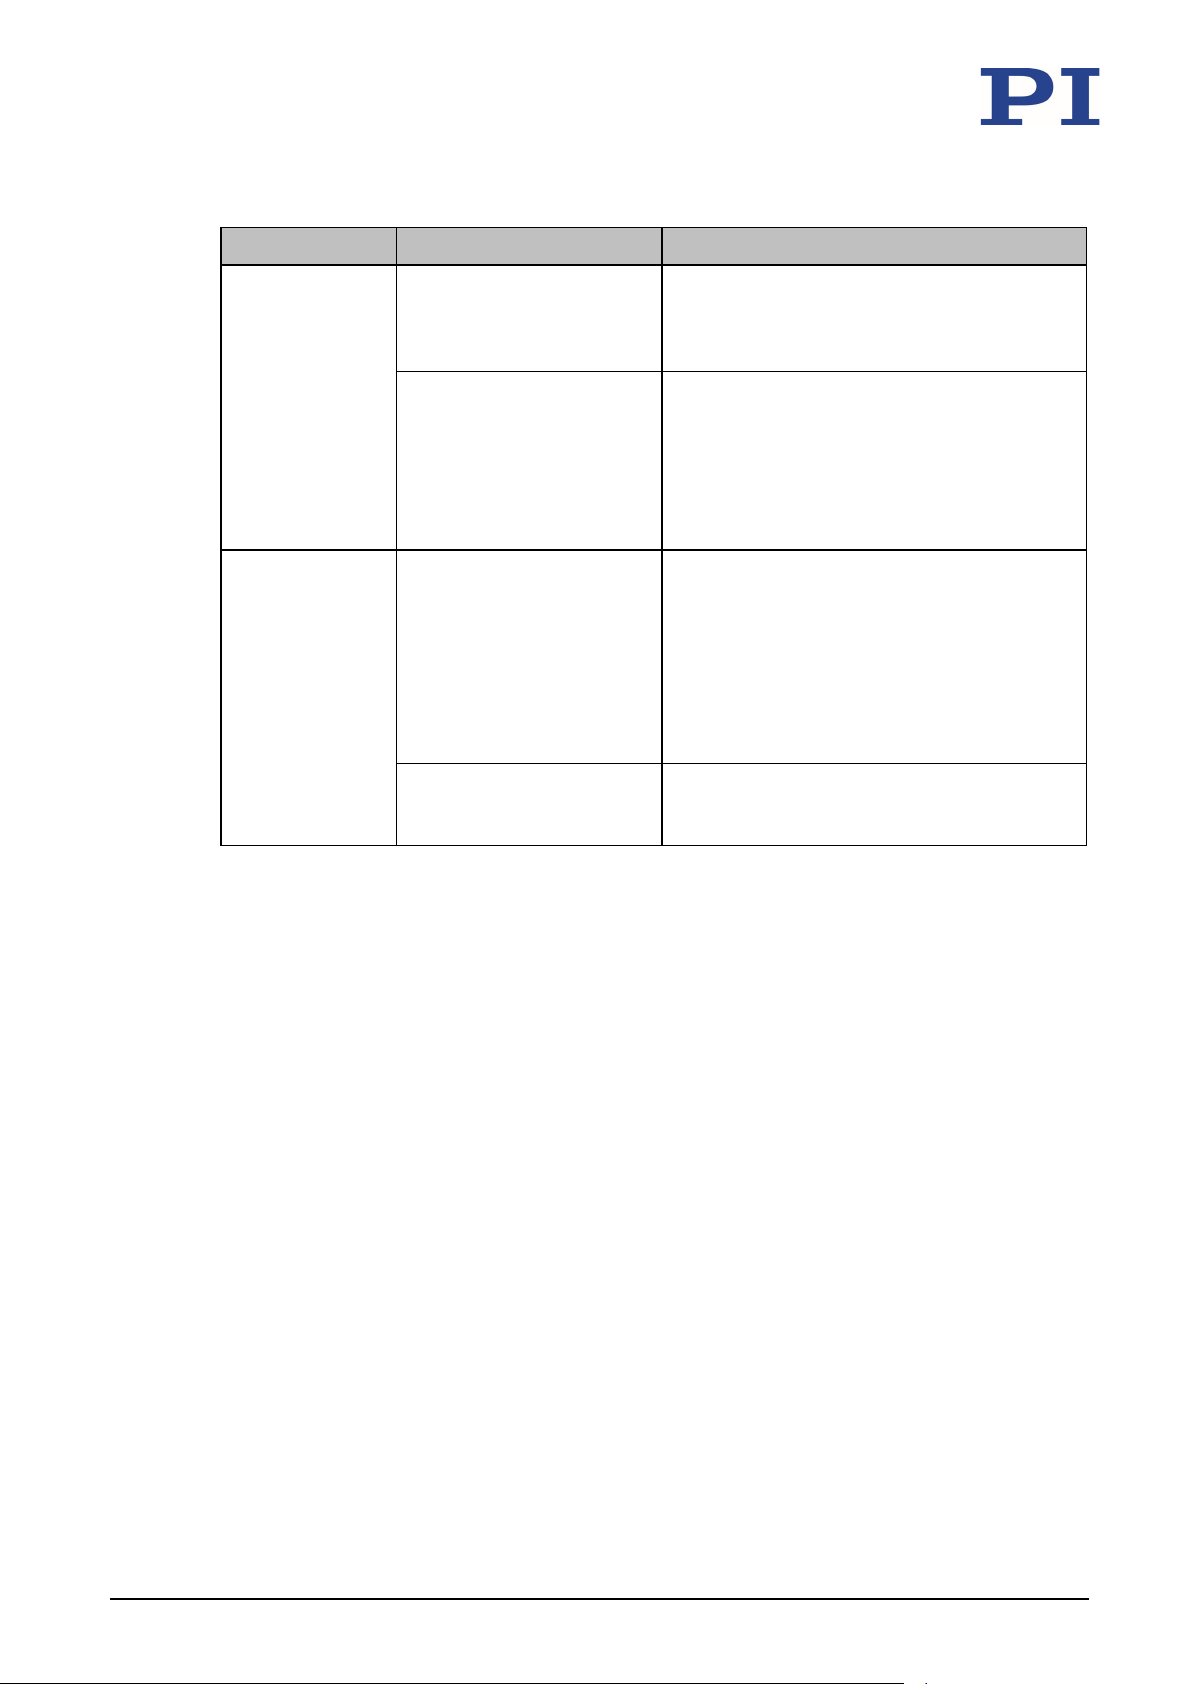
8 Troubleshooting
Axes were mixed up during
Pay attention to the assignment of the
Problem Possible causes Solution
connection (only with LEMO
connectors)
axes when connecting the positioner to
the controller. This assignment is
indicated by labels on the devices.
The positioner is not
connected to the
corresponding controller
(only when there are
several systems)
Pay attention to the assignment of the
devices when several systems are
connected. The assignment is indicated
on the calibration label of the controller
(see rear panel or bottom), which
contains the serial number of the
positioner to be connected.
The positioner
starts oscillating
or positions
inaccurately
Servo control parameters
incorrectly set because for
example, the load was
changed
1. Switch off the servo mode of the
corresponding motion axes immediately.
2. Check the settings of the servo control
parameters on the controller.
3. Adjust the servo control parameters on
the controller according to the load
change.
Open-loop operation near
the resonant frequency
In open-loop operation, operate the
positioner only with a frequency that is
below the resonant frequency.
If the problem with your system is not listed in the table above or cannot be solved as
described, contact our customer service department (p. 33).
32 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 37
9 Customer Service
9
Customer Service
For inquiries and orders, contact your PI sales engineer or send us an email ([email protected]).
If you have any questions concerning your system, provide the following information:
− Product and serial numbers of all products in the system
− Firmware version of the controller (if applicable)
− Version of the driver or the software (if applicable)
− Operating system on the PC (if applicable)
If possible: Take photographs or make videos of your system that can be sent to our
customer service department if requested.
The latest versions of the user manuals are available for download (p. 3) on our website.
P-611 Positioning Systems PZ253E Version: 1.1.0 33
Page 38
Page 39
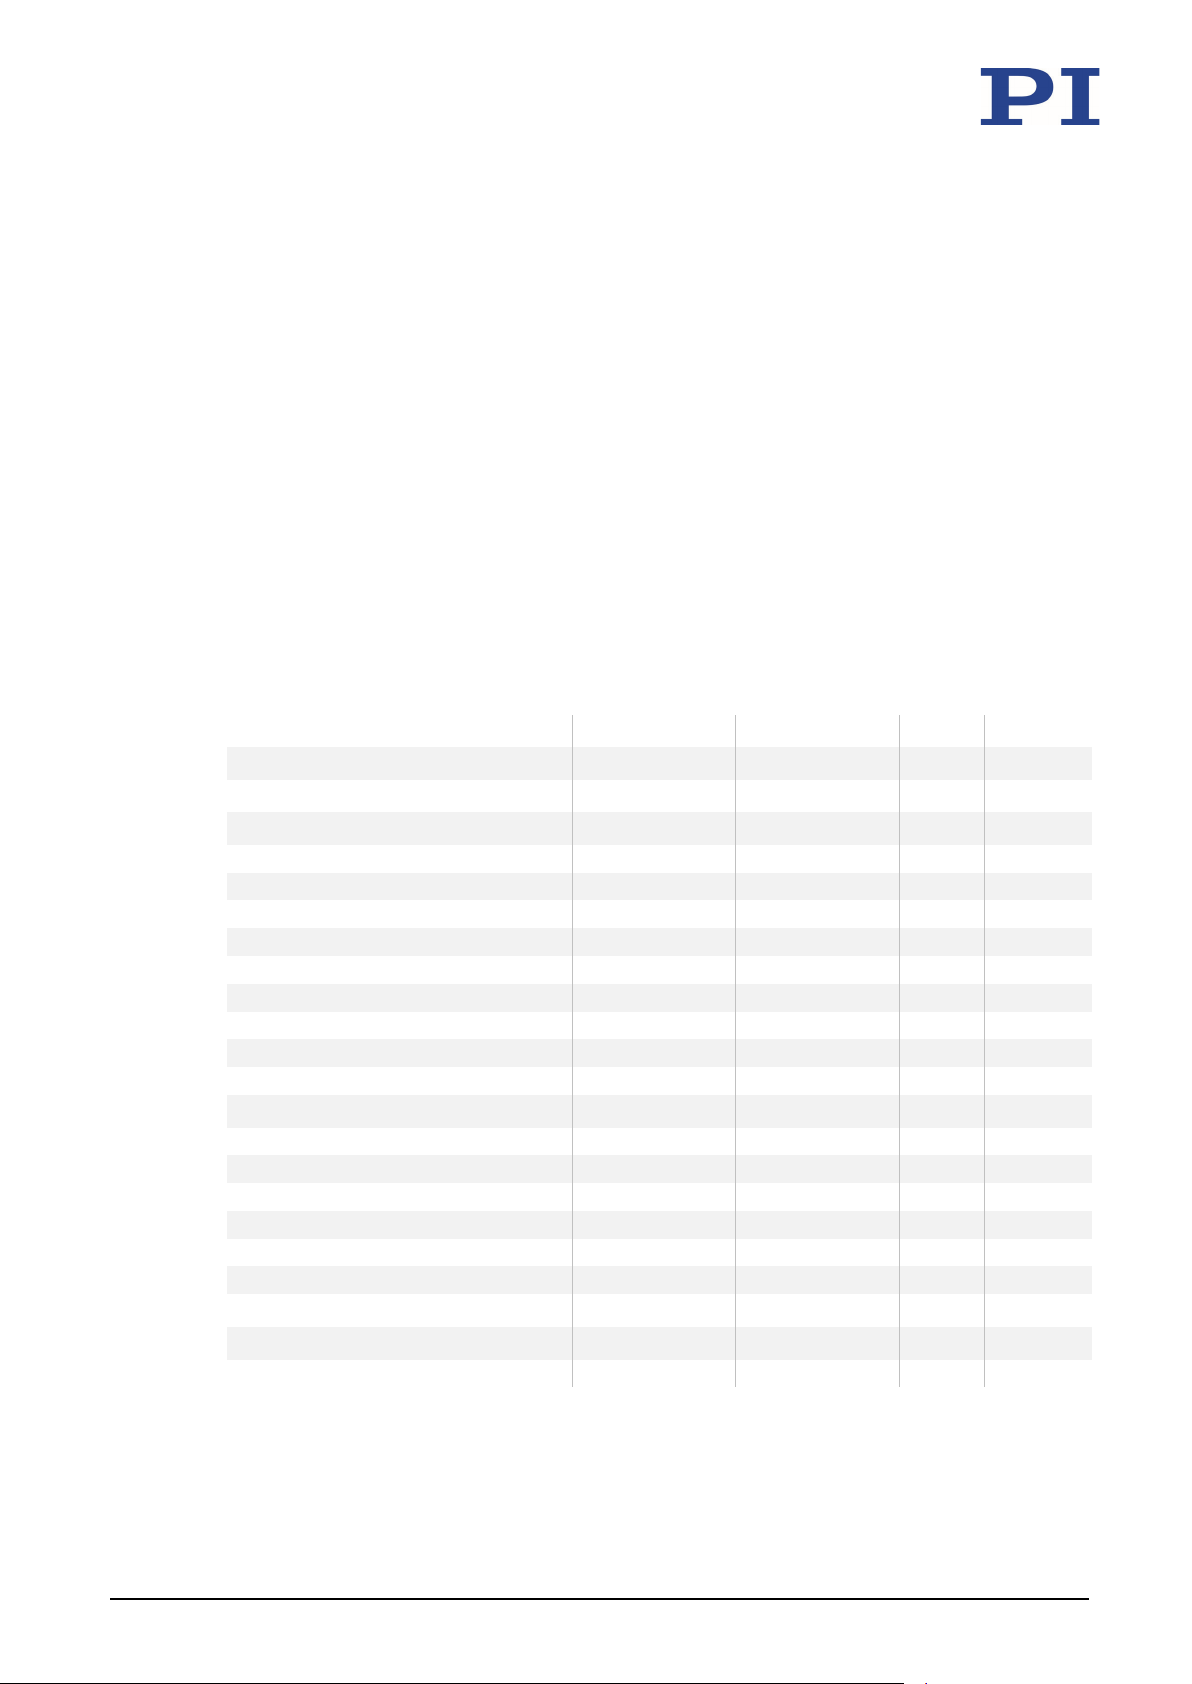
10 Technical Data
Pin Assignment ............................................................................................................................ 48
Resonant frequency, no load
400
400
Hz
±20 %
10
Technical Data
In this Chapter
Specifications ............................................................................................................................... 35
Dimensions .................................................................................................................................. 41
Torque for Stainless Steel Screws (A2-70) ................................................................................... 48
10.1 Specifications
10.1.1 Data Table
Active axes X X
Motion and positioning
Integrated sensor SGS -
Travel range at -20 to +120 V, open loop 120 120 µm +20 % / -0 %
Travel range, closed loop 100 - µm
Resolution, open loop 0.2 0.2 nm typ.
Resolution, closed loop 2 - nm typ.
Linearity error, closed loop 0.1 - % typ.
Repeatability <10 - nm typ.
Pitch ±5 ±5 µrad typ.
Yaw ±20 ±20 µrad typ.
Flatness 10 10 nm typ.
Mechanical properties
Stiffness in motion direction 0.2 0.2 N/µm ±20 %
Resonant frequency, under load, 30 g 300 300 Hz ±20 %
Resonant frequency, under load, 100 g 195 195 Hz ±20 %
Push/pull force capacity in motion direction 15 / 10 15 / 10 N max.
Load capacity 15 15 N max.
Drive properties
Ceramic type PICMA® P-885 PICMA® P-885
Electrical capacitance 1.5 1.5 µF ±20 %
P-611.1S P-611.10 Unit Tolerance
P-611 Positioning Systems PZ253E Version: 1.1.0 35
Page 40
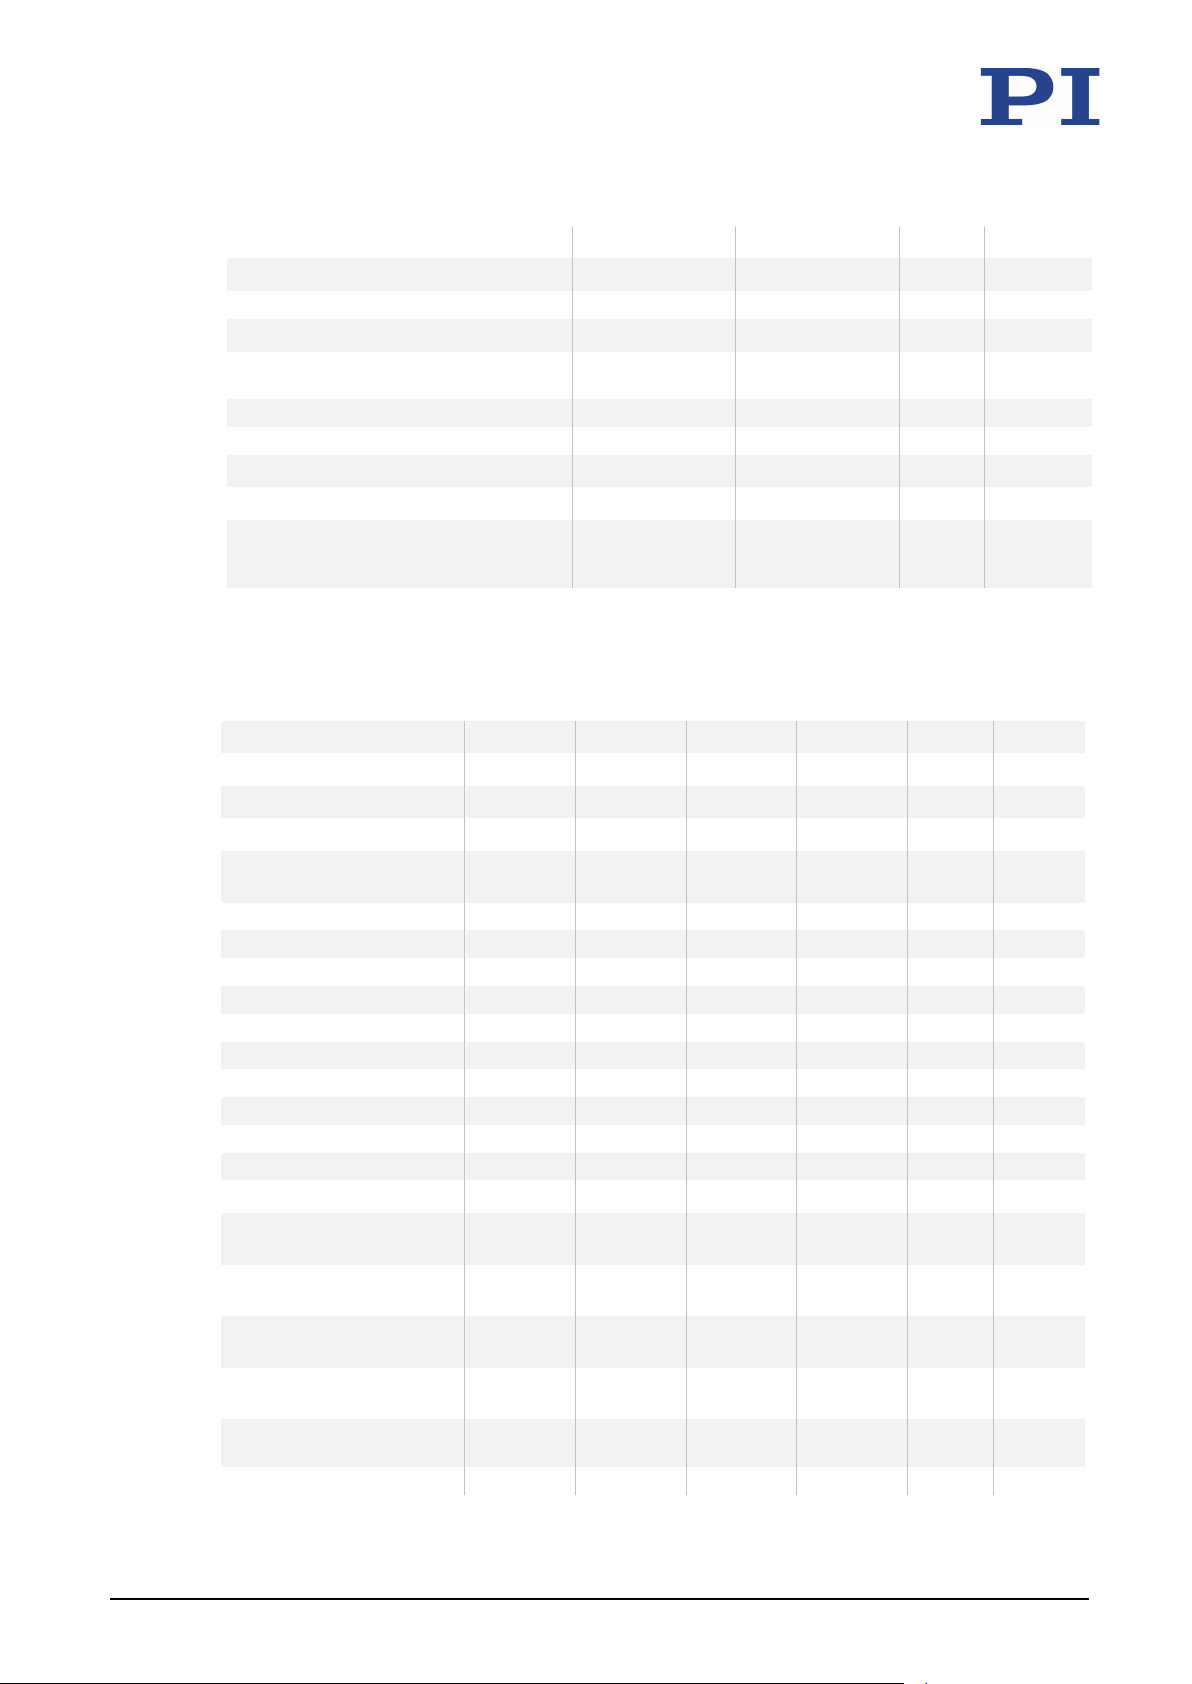
10 Technical Data
Operating temperature range
-20 to 80
-20 to 80
°C
Mass
0.135
0.135
kg
±5 %
Sensor connection
LEMO
-
Tilt θX (motion in Z)
– – ±10
±10
µrad
typ.
Miscellaneous
Material Aluminum, steel Aluminum, steel
Dimensions
Cable length 1.5 1.5 m ±10 mm
Voltage connection LEMO LEMO
Recommended electronics
The resolution of the system is limited only by the noise of the amplifier and the measuring technology because PI
piezo nanopositioning systems are free of friction.
All specifications based on room temperature (22 °C ±3 °C).
P-611.1S P-611.10 Unit Tolerance
44 mm × 44 mm ×
17 mm
E-503, E-505, E-610,
E-621, E-625, E-665,
E-836
44 mm × 44 mm ×
17 mm
E-503, E-505, E-610,
E-621, E-625, E-665,
E-836
Active axes X, Y X, Y X, Z X, Z
Motion and positioning
Integrated sensor SGS – SGS –
Travel range at -20 to 120 V,
open loop
Travel range, closed loop 100 – 100 – µm
Resolution, open loop 0.2 0.2 0.2 0.2 nm typ.
Resolution, closed loop 2 – 2 – nm typ.
Linearity error 0.1 – 0.1 – % typ.
Repeatability <10 – <10 – nm typ.
Pitch in X, Y ±5 ±5 ±5 ±5 µrad typ.
P-611.2S P-611.20 P-611.XZS P-611.XZ0 Unit Tolerance
120 120 120 120 µm +20 % /
-0 %
36 Version: 1.1.0 PZ253E P-611 Positioning Systems
Yaw in X ±20 ±20 ±20 ±20 µrad typ.
Yaw in Y ±10 ±10 – – µrad typ.
Tilt θY (motion in Z) – – ±10 ±10 µrad typ.
Mechanical properties
Stiffness 0.2 0.2 0.2
Resonant frequency, no load X: 345;
Resonant frequency, under
load, 30 g
Resonant frequency, under
load, 100 g
Push/pull force capacity in
motion direction
Load capacity 15 15 15 15 N max.
0.2
Z: 0.35
X: 345;
Y: 270
X: 270;
Y: 225
X: 180;
Y: 165
15 / 10 15 / 10 15 / 10 15 / 10 N max.
Y: 270
X: 270;
Y: 225
X: 180;
Y: 165
X: 365;
Z: 340
X: 280;
Z: 295
X: 185;
Z: 230
Z: 0.35
X: 365;
Z: 340
X: 280;
Z: 295
X: 185;
Z: 230
N/µm ±20 %
Hz ±20 %
Hz ±20 %
Hz ±20 %
Page 41
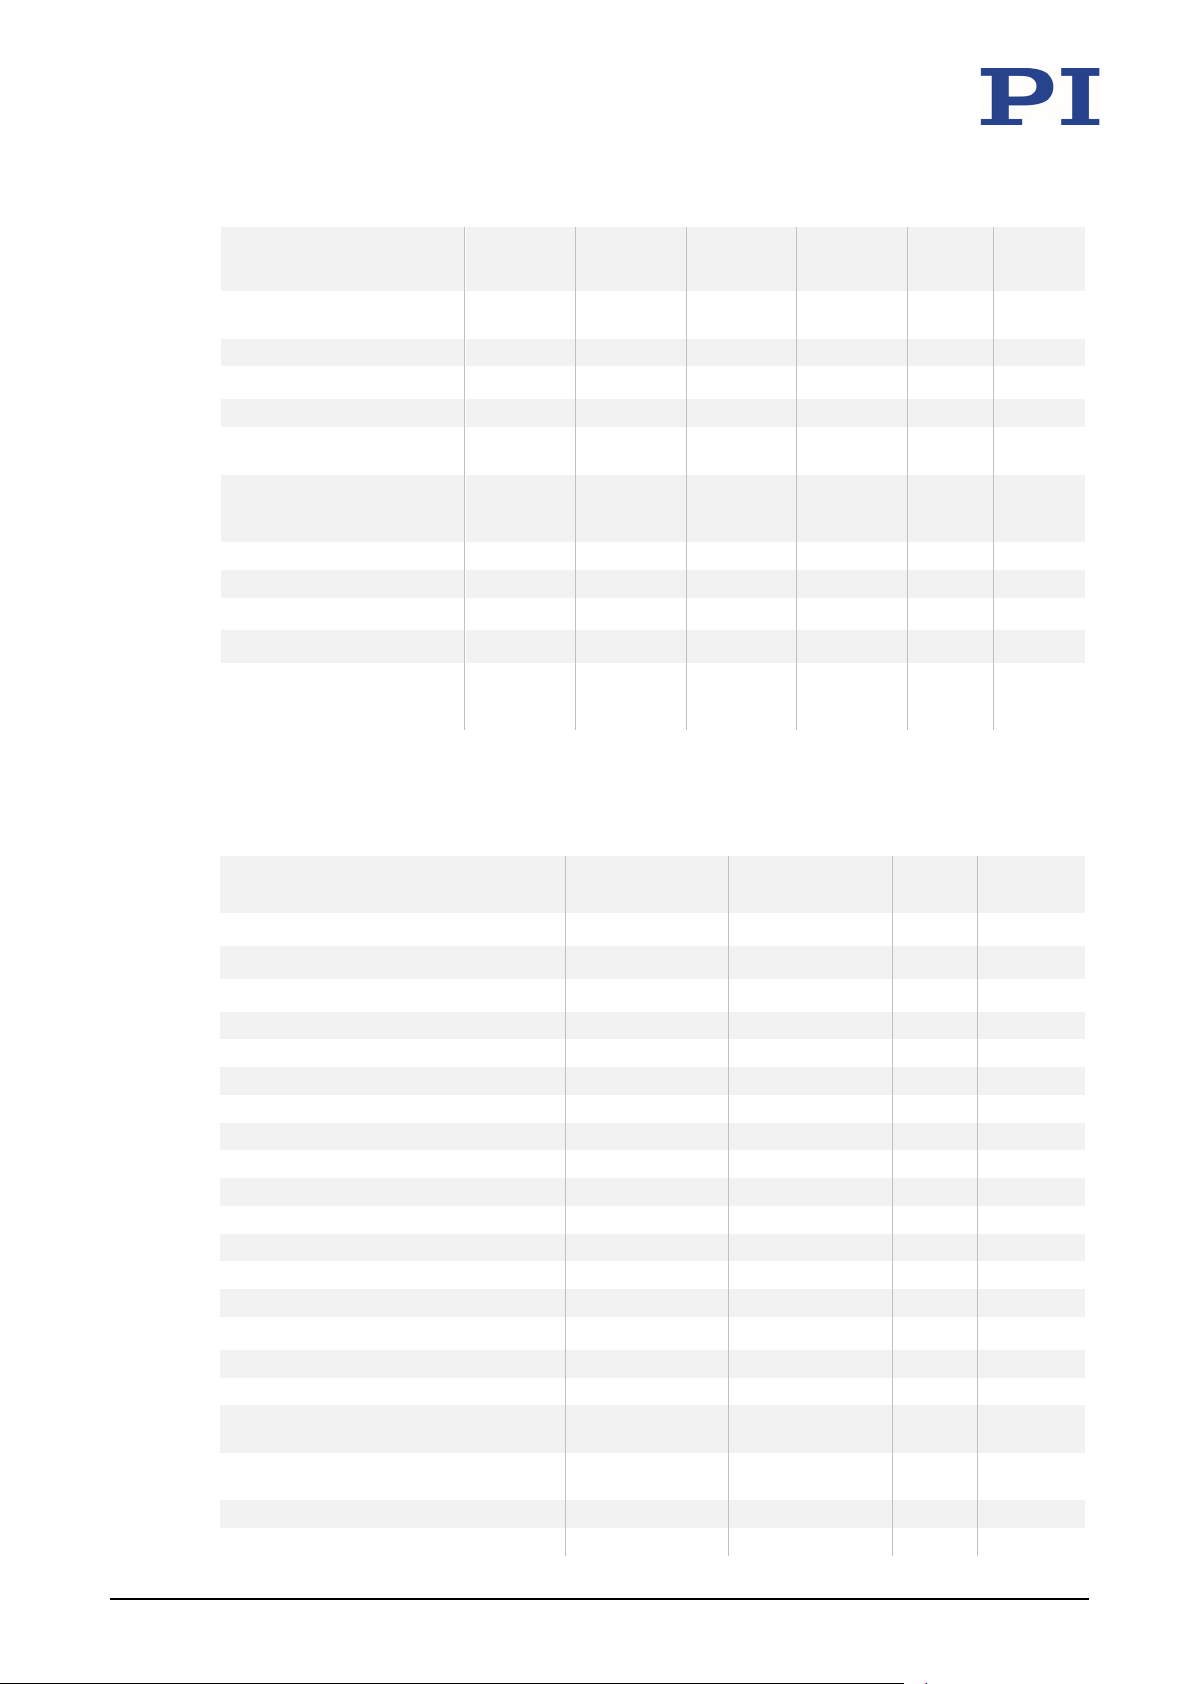
10 Technical Data
Ceramic type
Operating temperature range
-20 to 80
-20 to 80
-20 to 80
-20 to 80
°C
Active axes
X, Y, Z
X, Y, Z
Travel range, closed loop
100 / axis
–
µm
Yaw in Y
±10
±10
µrad
typ.
270 / 185 / 230
270 / 185 / 230
Hz
±20 %
Drive properties
Electrical capacitance 1.5 1.5 1.5 1.5 µF ±20 %
Miscellaneous
Material
Dimensions
Mass 0.235 0.235 0.27 0.27 kg ±5 %
Cable length 1.5 1.5 1.5 1.5 m ±10 mm
Sensor connection LEMO – LEMO –
Voltage connection LEMO LEMO LEMO LEMO
Recommended electronics
The resolution of the system is limited only by the noise of the amplifier and the measuring technology because PI
piezo nanopositioning systems are free of friction.
All specifications based on room temperature (22 °C ±3 °C).
P-611.2S P-611.20 P-611.XZS P-611.XZ0 Unit Tolerance
PICMA®
P-885
Aluminum,
steel
44 mm ×
44 mm ×
25 mm
E-503, E-505,
E-663, E-664,
E-727
PICMA®
P-885
Aluminum,
steel
44 mm ×
44 mm ×
25 mm
E-503, E-505,
E-663, E-664,
E-727
PICMA®
P-885
Aluminum,
steel
44 mm ×
44 mm ×
34 mm
E-503, E-505,
E-663, E-664,
E-727
PICMA®
P-885
Aluminum,
steel
44 mm ×
44 mm ×
34 mm
E-503, E-505,
E-663, E-664,
E-727
Motion and positioning
Integrated sensor SGS
Travel range at -20 to 120 V, open loop 120 / axis 120 / axis µm +20 % / -0 %
Resolution, open loop 0.2 0.2 nm typ.
Resolution, closed loop 1 – nm typ.
Linearity error 0.1 – % typ.
Repeatability <10 – nm typ.
Pitch in X, Y ±5 ±5 µrad typ.
Tilt θX (motion in Z) ±10 ±10 µrad typ.
Yaw in X ±20 ±20 µrad typ.
Tilt θY (motion in Z) ±10 ±10 µrad typ.
Mechanical properties
Stiffness 0.3 0.3 N/µm ±20 %
Resonant frequency X / Y / Z, no load 350 / 220 / 250 350 / 220 / 250 Hz ±20 %
Resonant frequency under load in X / Y / Z,
30 g
Resonant frequency under load in X / Y / Z,
100 g
Push/pull force capacity in motion direction 15 / 10 15 / 10 N max.
Load capacity 15 15 N max.
P-611.3S
P-611.3SF
180 / 135 / 200 180 / 135 / 200 Hz ±20 %
P-611.3O
P-611.3OF
Unit Tolerance
P-611 Positioning Systems PZ253E Version: 1.1.0 37
Page 42
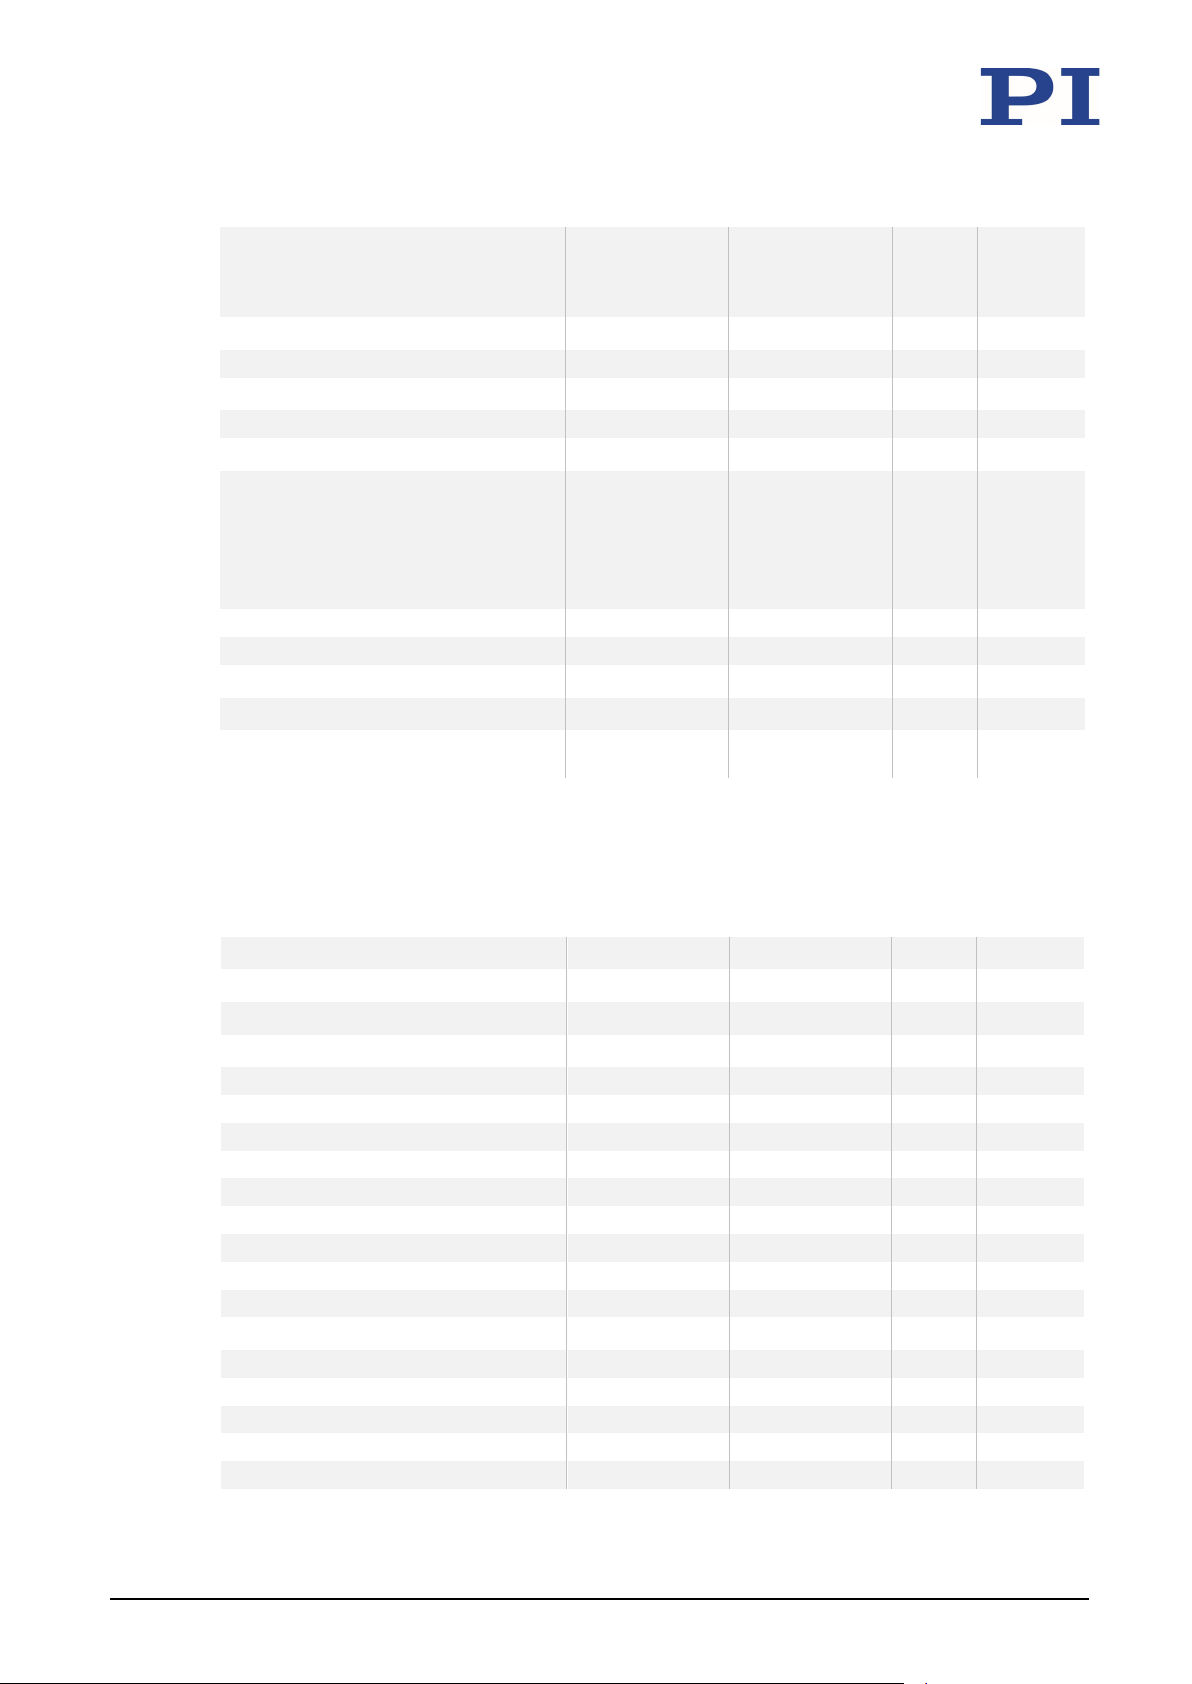
10 Technical Data
Drive properties
Ceramic type PICMA® P-885 PICMA® P-885
P-611.3S
P-611.3SF
P-611.3O
P-611.3OF
Unit Tolerance
Electrical capacitance 1.5 1.5 µF ±20 %
Miscellaneous
Operating temperature range -20 to 80 -20 to 80 °C
Material Aluminum, steel Aluminum, steel
Dimensions P-611.3S:
44 mm × 44 mm ×
43.2 mm
P-611.3SF:
48 mm × 50 mm ×
44.2 mm
P-611.3O:
44 mm × 44 mm ×
43.2 mm
P-611.3OF:
44 mm × 50 mm ×
44.2 mm
Mass 0.32 0.32 kg ±5 %
Cable length 1.5 1.5 m ±10 mm
Voltage connection D-sub 25 (m) D-sub 25 (m)
Sensor connection D-sub 25 (m) –
Recommended electronics
E-503, E-505, E-663,
E-664, E-727
E-503, E-505, E-663,
E-664, E-727
The resolution of the system is limited only by the noise of the amplifier and the measuring technology because PI
piezo nanopositioning systems are free of friction.
Adapter cables with LEMO connectors for sensor and operating voltage available.
All specifications based on room temperature (22 °C ±3 °C).
Active axes Z Z
Motion and positioning
Integrated sensor SGS -
P-611.ZS P-611.Z0 Unit Tolerance
Travel range at -20 to +120 V, open loop 120 120 µm +20 % / -0 %
Travel range, closed loop 100 - µm
Resolution, open loop 0.2 0.2 nm typ.
Resolution, closed loop 2 - nm typ.
Linearity error 0.1 - % typ.
Repeatability <10 - nm typ.
Tilt θZ (motion in Z) ±5 ±5 µrad typ.
Tilt θX (motion in Z) ±20 ±20 µrad typ.
Tilt θY (motion in Z) ±5 ±5 µrad typ.
Mechanical properties
Stiffness 0.45 0.45 N/µm ±20 %
Resonant frequency, no load 460 460 Hz ±20 %
Resonant frequency under load, 30 g 375 375 Hz ±20 %
Resonant frequency under load, 100 g 265 265 Hz ±20 %
Push/pull force capacity 15 / 10 15 / 10 N max.
38 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 43
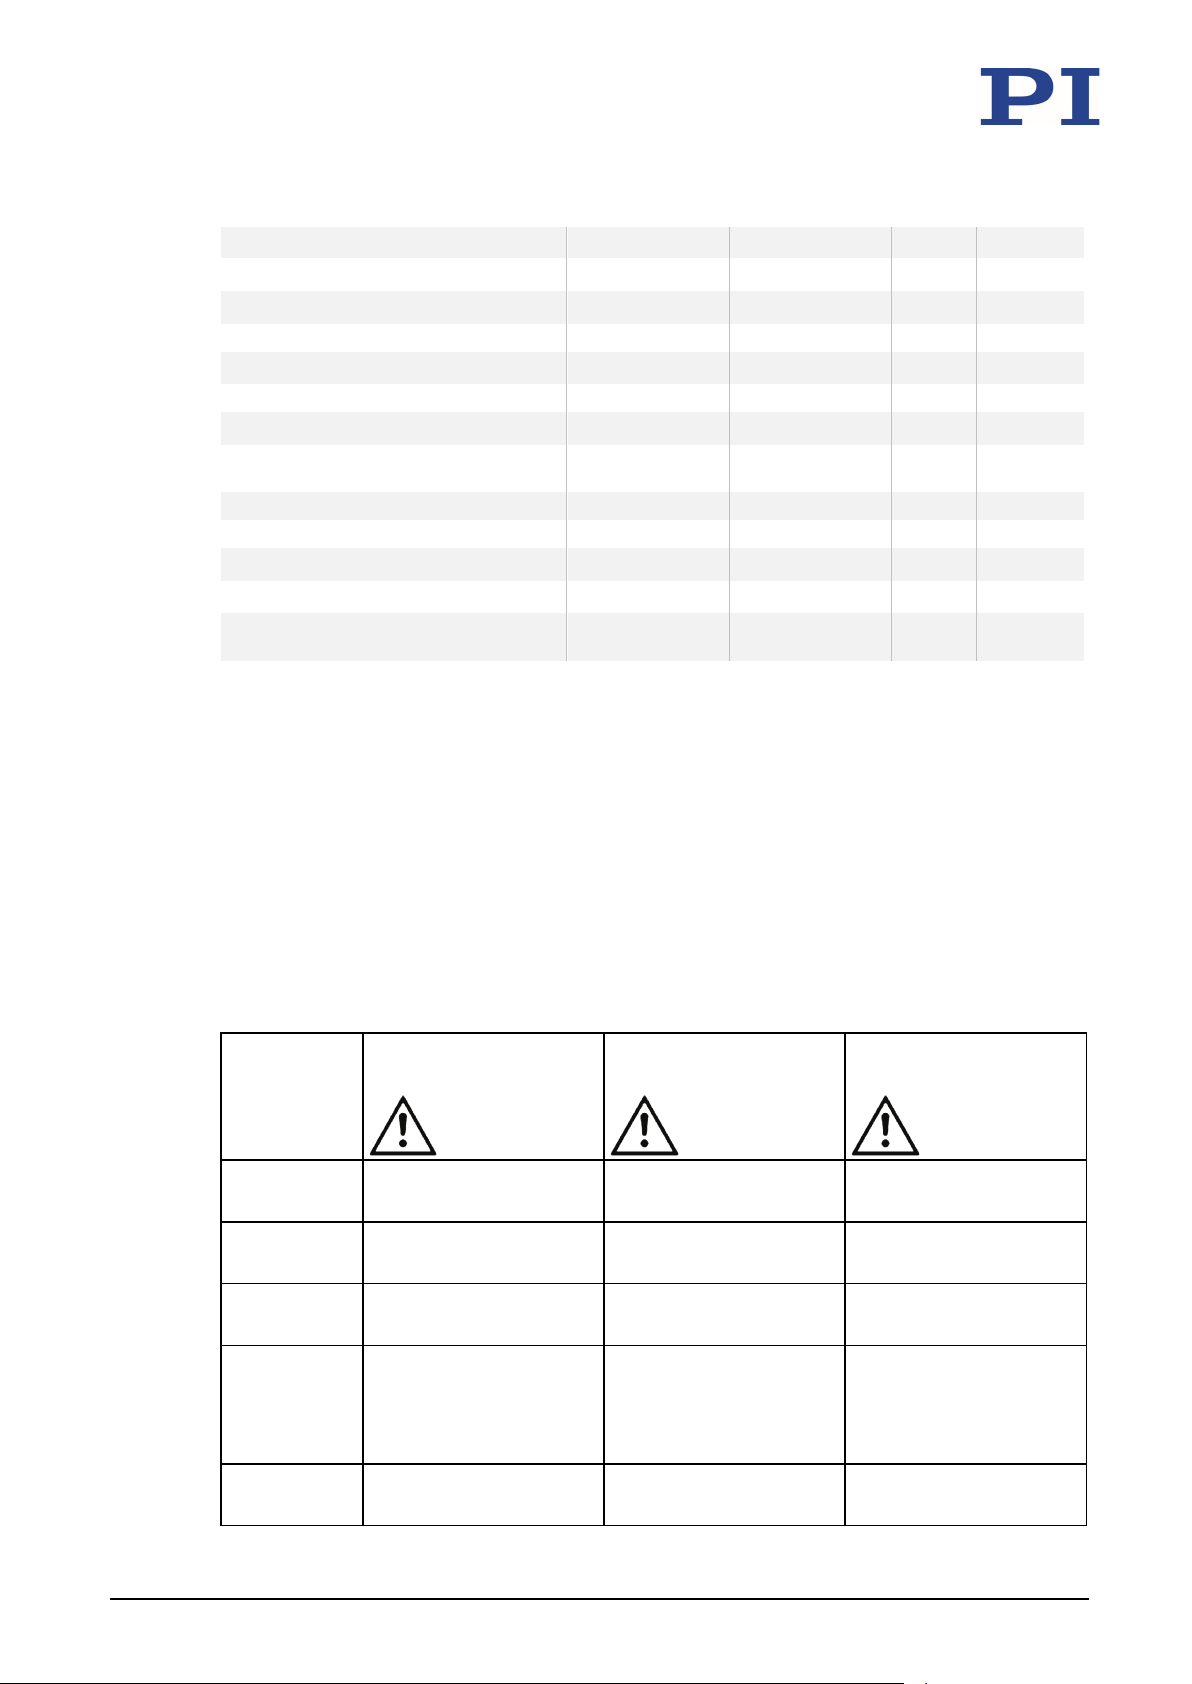
10 Technical Data
Ceramic type
PICMA® P-885
PICMA® P-885
Recommended electronics
Drive properties
Electrical capacitance 1.5 1.5 µF ±20 %
Miscellaneous
Operating temperature range -20 to 80 -20 to 80 °C
Material Aluminum, steel Aluminum, steel
Dimensions
Mass 176 176 g ±5 %
Cable length 1.5 1.5 m ±10 mm
Sensor connection LEMO -
Voltage connection LEMO LEMO
The resolution of the system is limited only by the noise of the amplifier and the measuring technology because PI
piezo nanopositioning systems are free of friction.
All specifications based on room temperature (22 °C ±3 °C).
System properties
System configuration: P-611.ZS and E-665.SR controller with 30 g load
Small signal bandwidth: 40 Hz
Settling time (10 % step width): 25 ms
P-611.ZS P-611.Z0 Unit Tolerance
44 mm × 44 mm ×
27 mm
E-610, E-625, E-665,
E-836
44 mm × 44 mm ×
27 mm
E-610, E-625, E-665,
E-836
10.1.2 Maximum Ratings
P-611 positioners are designed for the following operating data:
Positioner Maximum operating
voltage
P-611.1S
P-611.10
P-611.2S
P-611.20
P-611.XZS
P-611.XZ0
P-611.3S
P-611.3SF
P-611.3O
P-611.3OF
P-611.ZS
P-611.Z0
-20 to +120 V 133 Hz 3.9 W
-20 to +120 V 115 Hz (in X)
-20 to +120 V 122 Hz (in X)
-20 to +120 V 117 Hz (in X)
-20 to +120 V 153 Hz 4.5 W
Maximum operating
frequency (no load)
90 Hz (in Y)
113 Hz (in Z)
73 Hz (in Y)
83 Hz (in Z)
Maximum power
consumption
3.4 W (in X)
2.6 W (in Y)
3.6 W (in X)
3.3 W (in Z)
3.4 W (in X)
2.1 W (in Y)
2.4 W (in Z)
P-611 Positioning Systems PZ253E Version: 1.1.0 39
Page 44
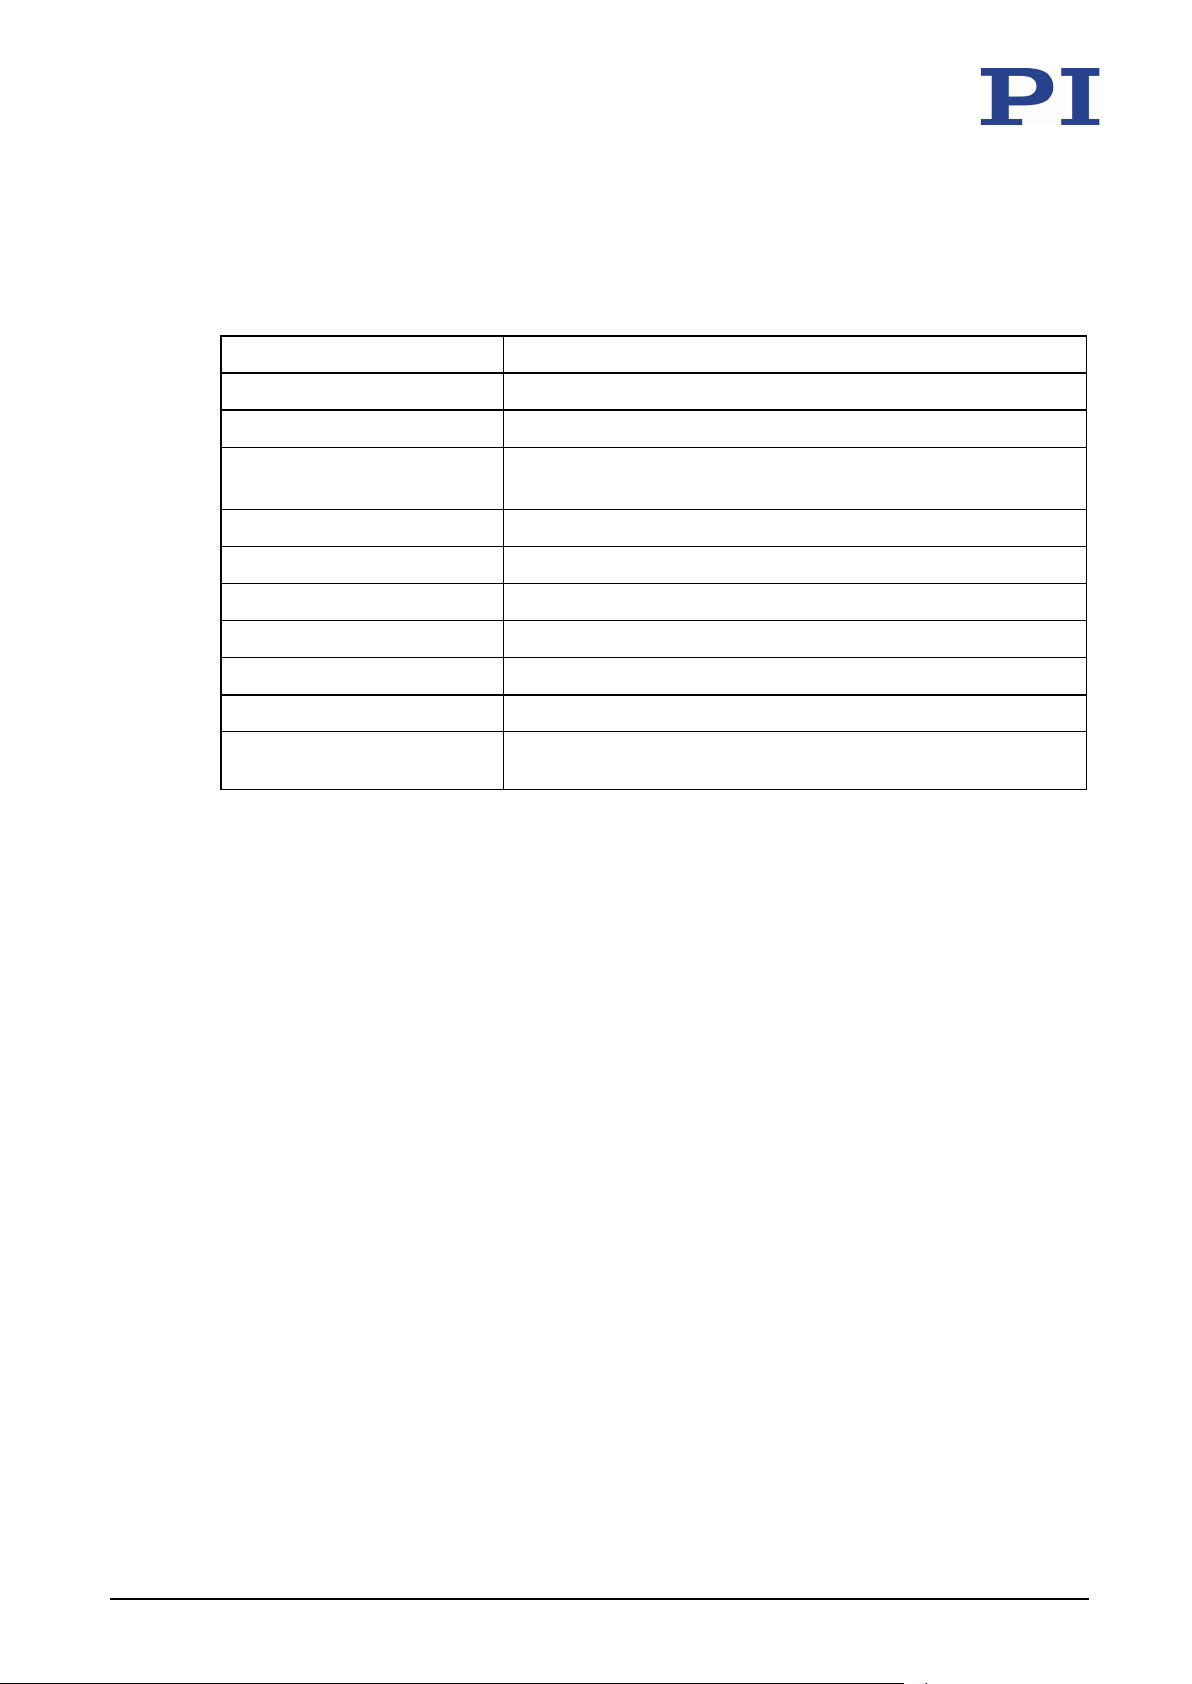
10 Technical Data
Maximum altitude
2000 m
Relative humidity
Highest relative humidity 80 % for temperatures up to 31 °C
Operating temperature
–20 °C to 80 °C
Overvoltage category
II
Degree of pollution
1
10.1.3 Ambient Conditions and Classifications
Pay attention to the following ambient conditions and classifications for the P-611:
Area of application For indoor use only
Air pressure 1100 hPa to 0.1 hPa
Decreasing linearly to 50 % relative humidity at 40 °C
Storage temperature –20 °C to 80 °C
Transport temperature –25 °C to 85 °C
Protection class I
Degree of protection
IP20
according to IEC 60529
40 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 45
10 Technical Data
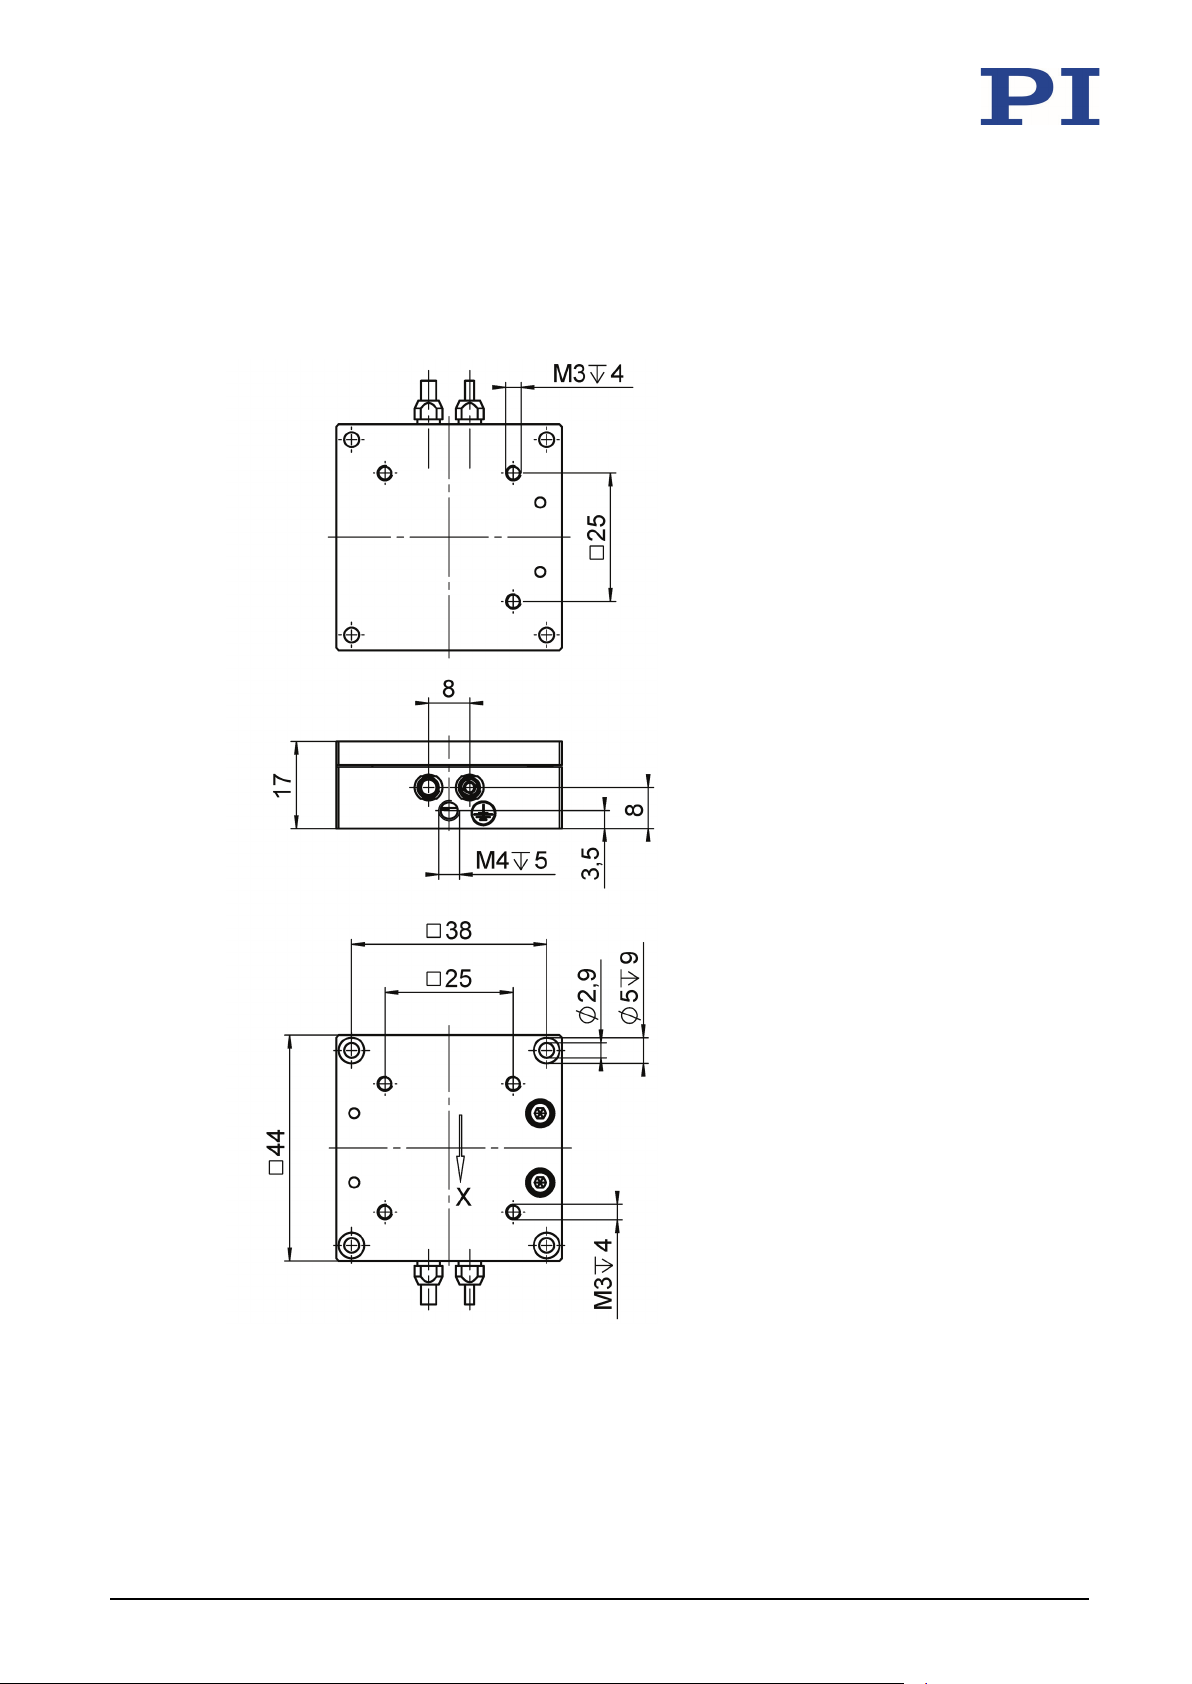
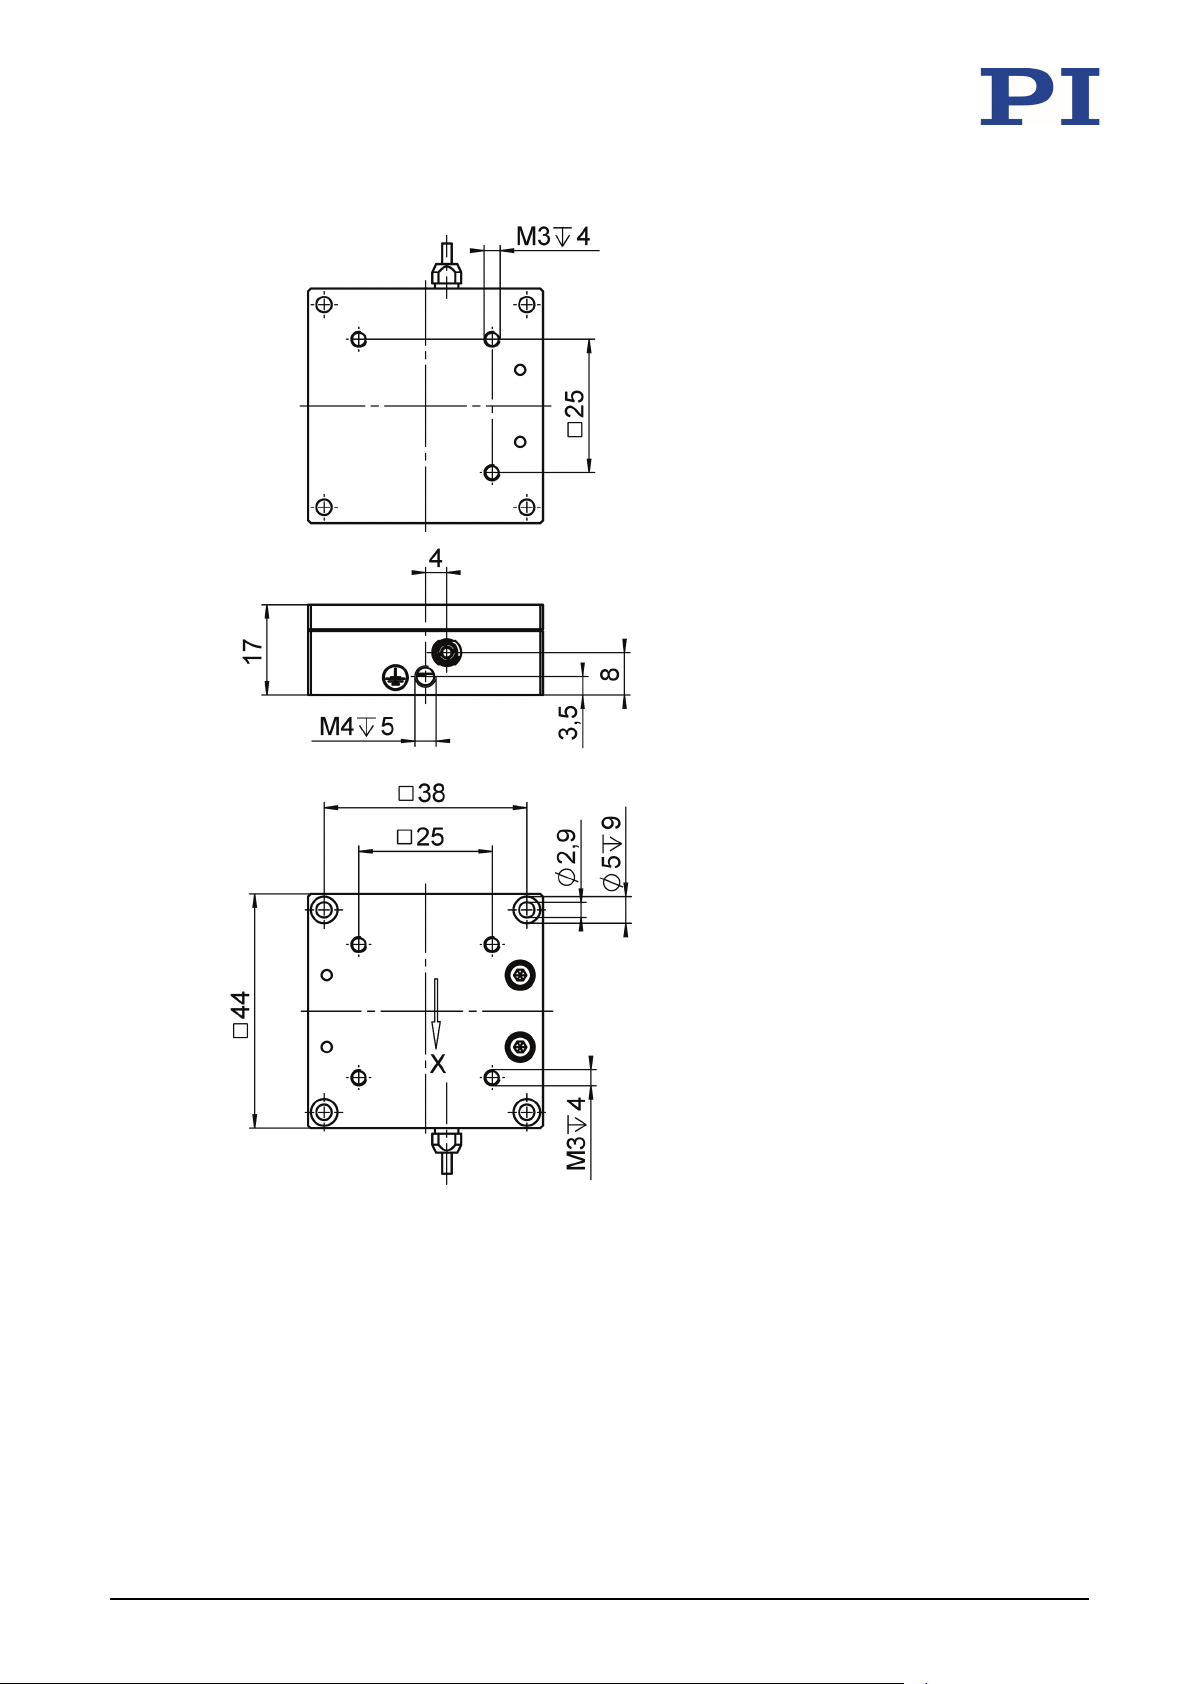
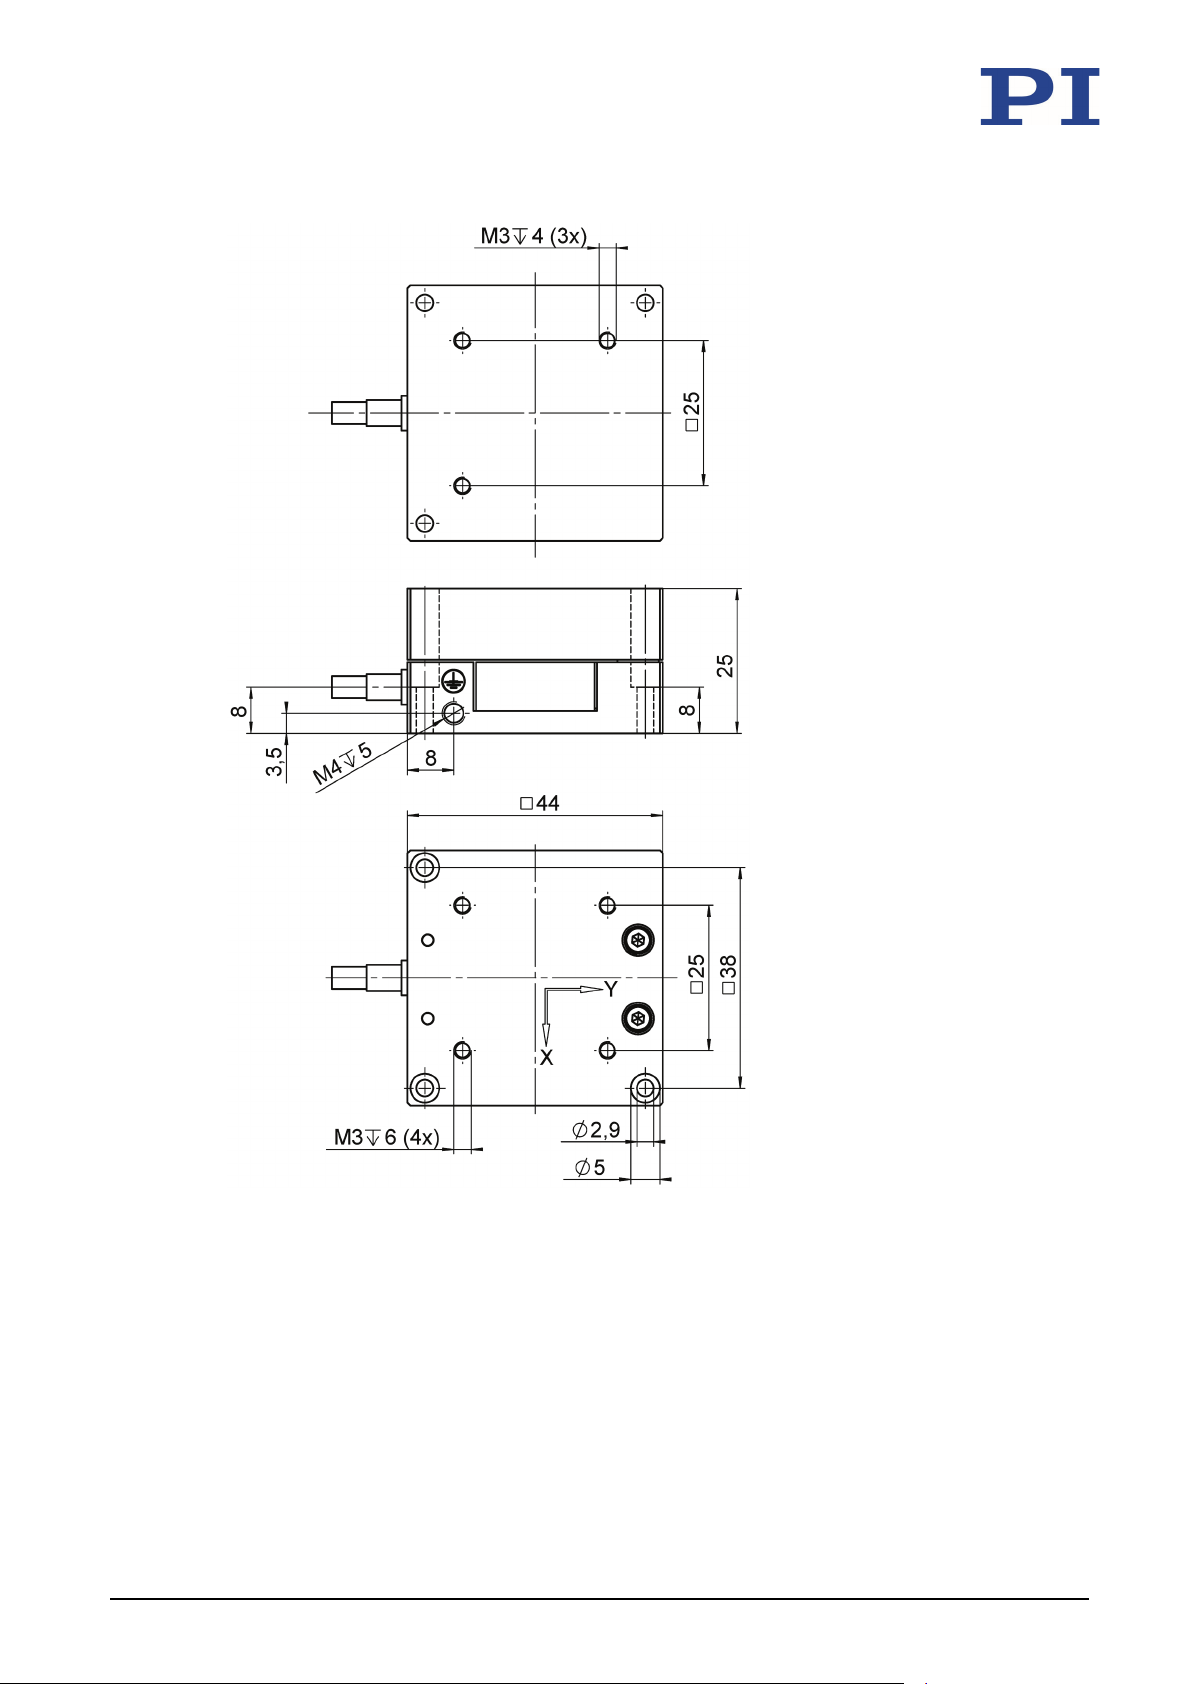
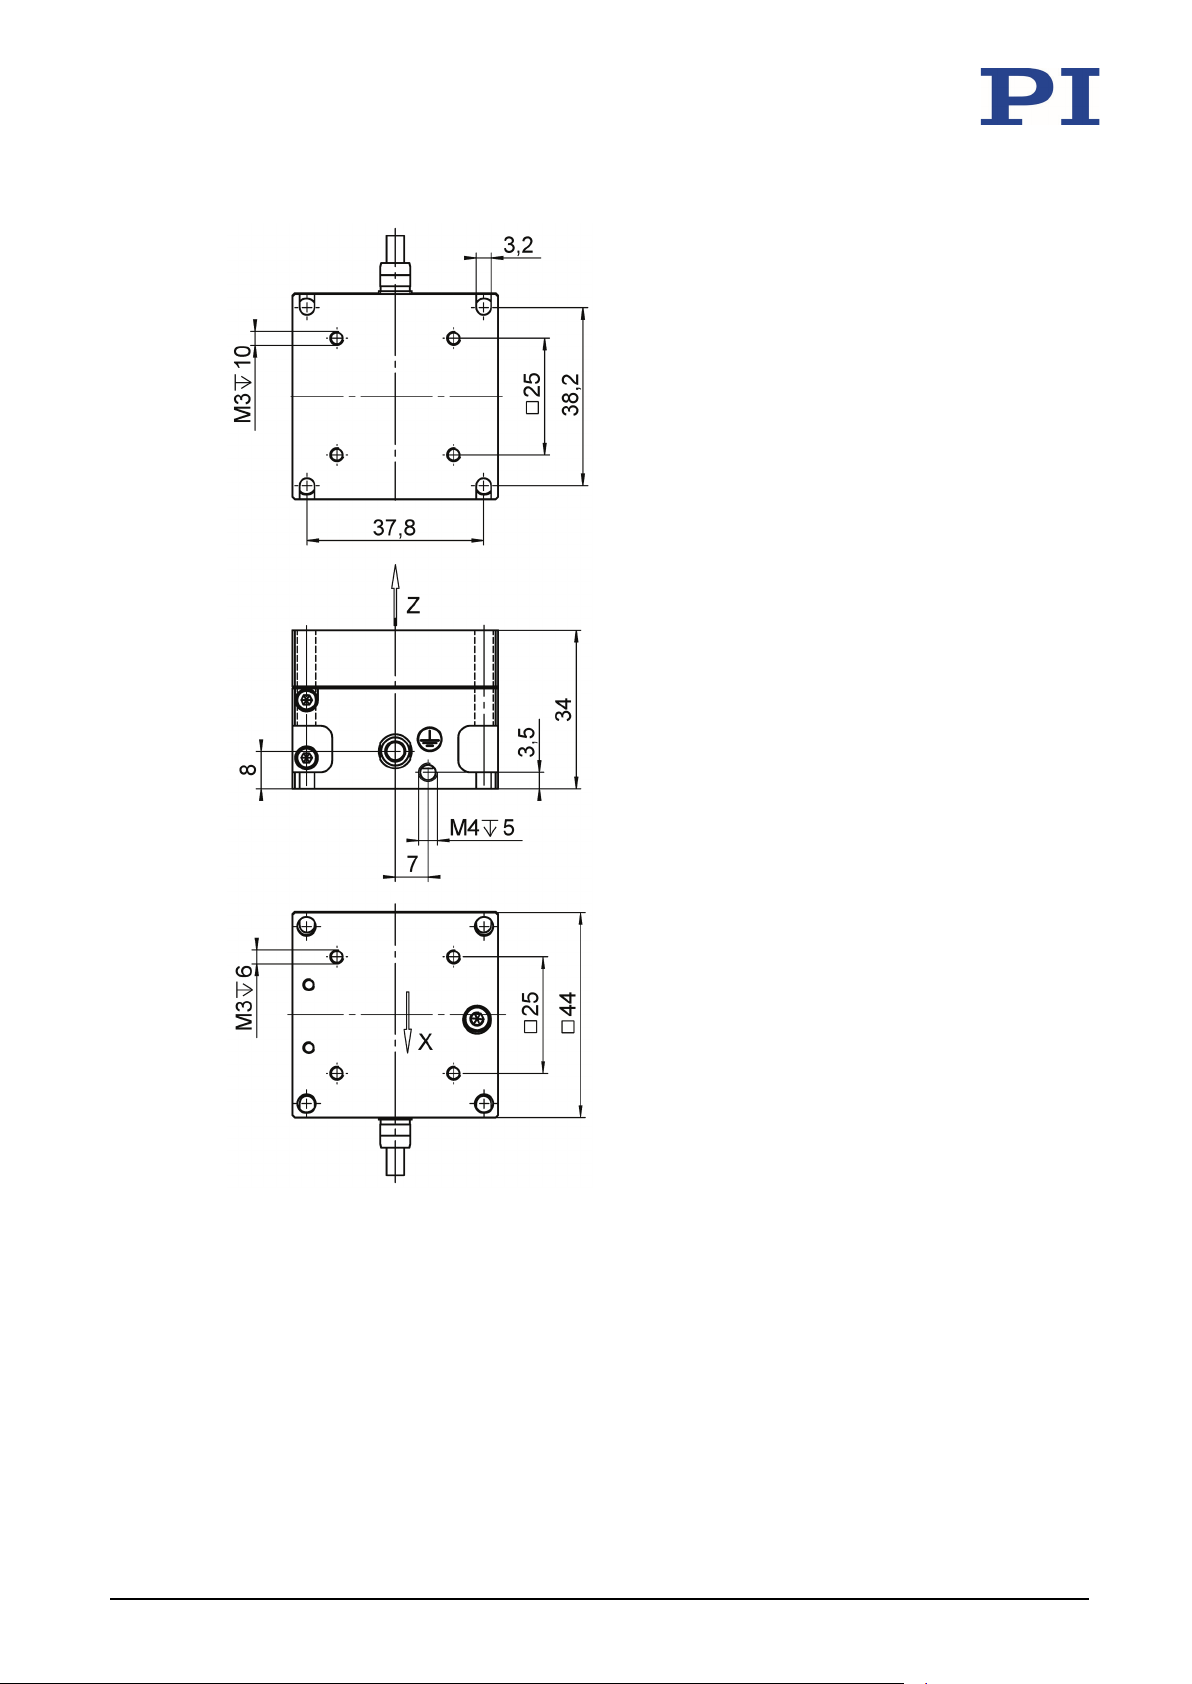
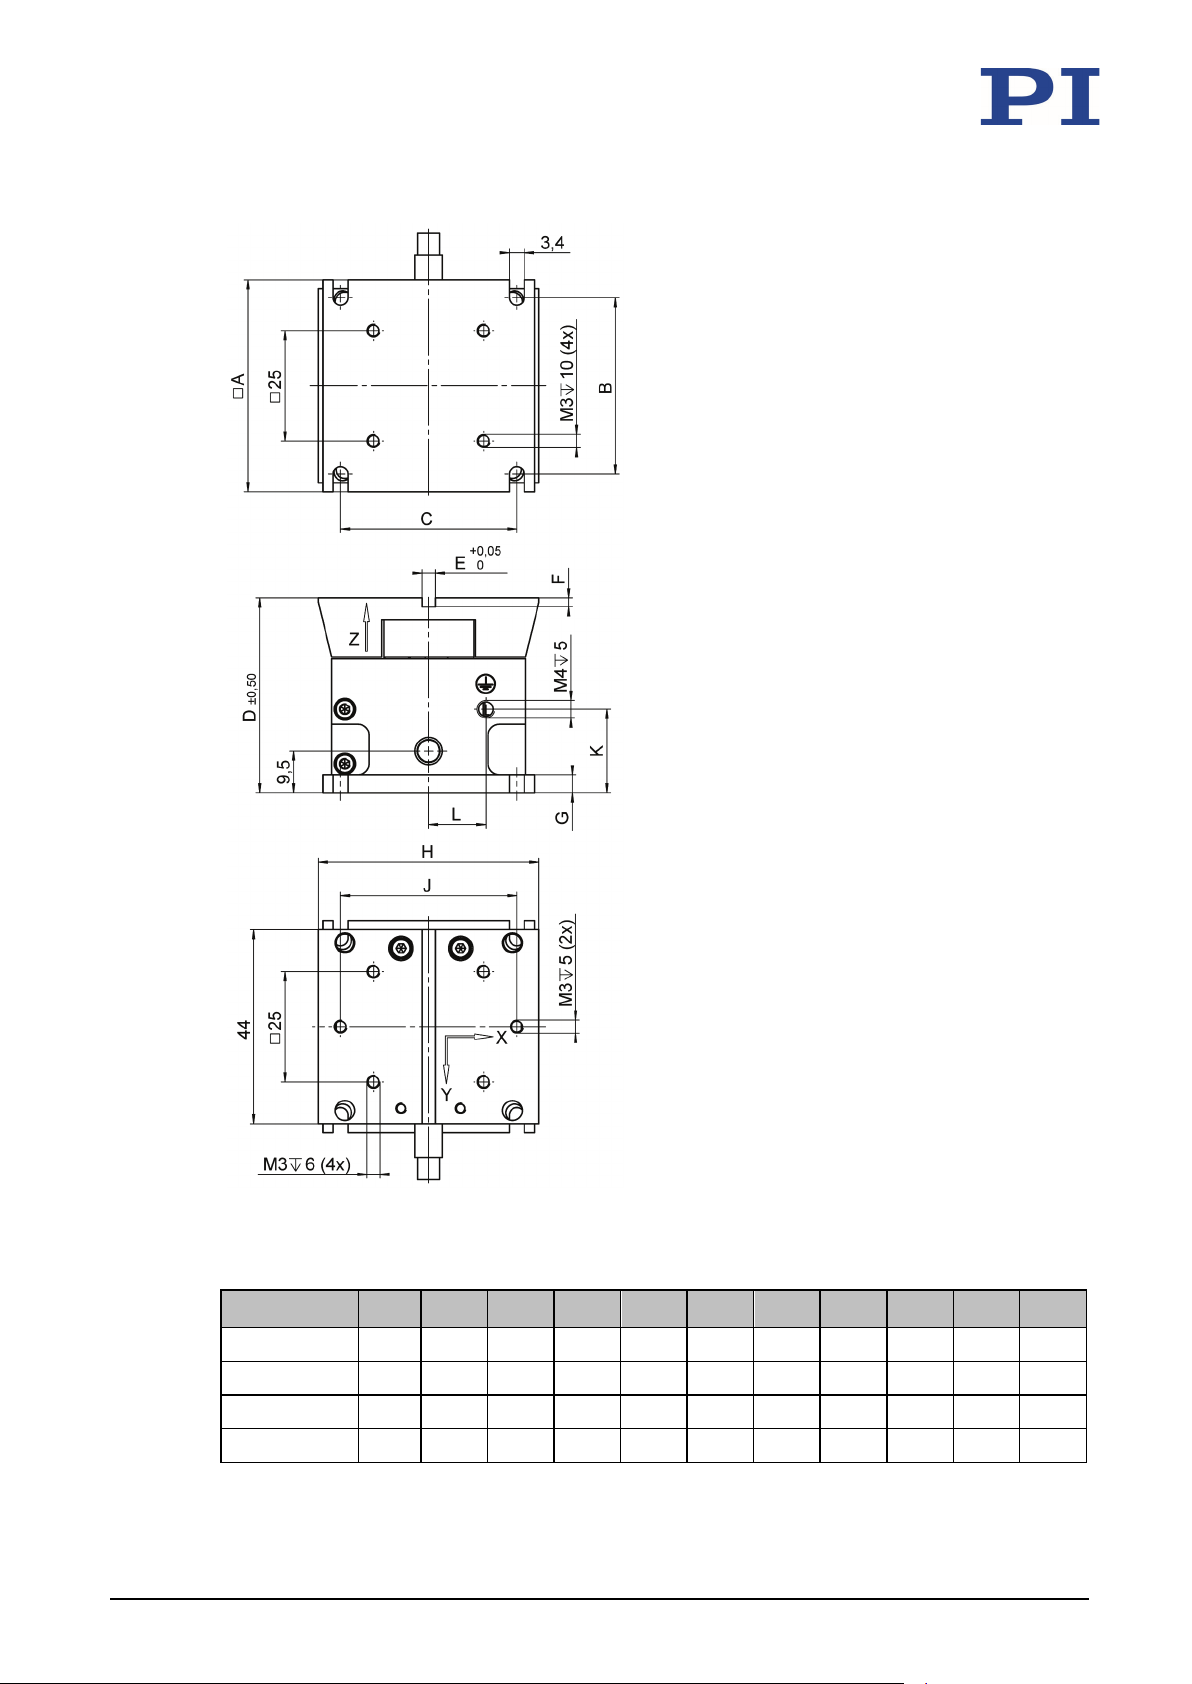
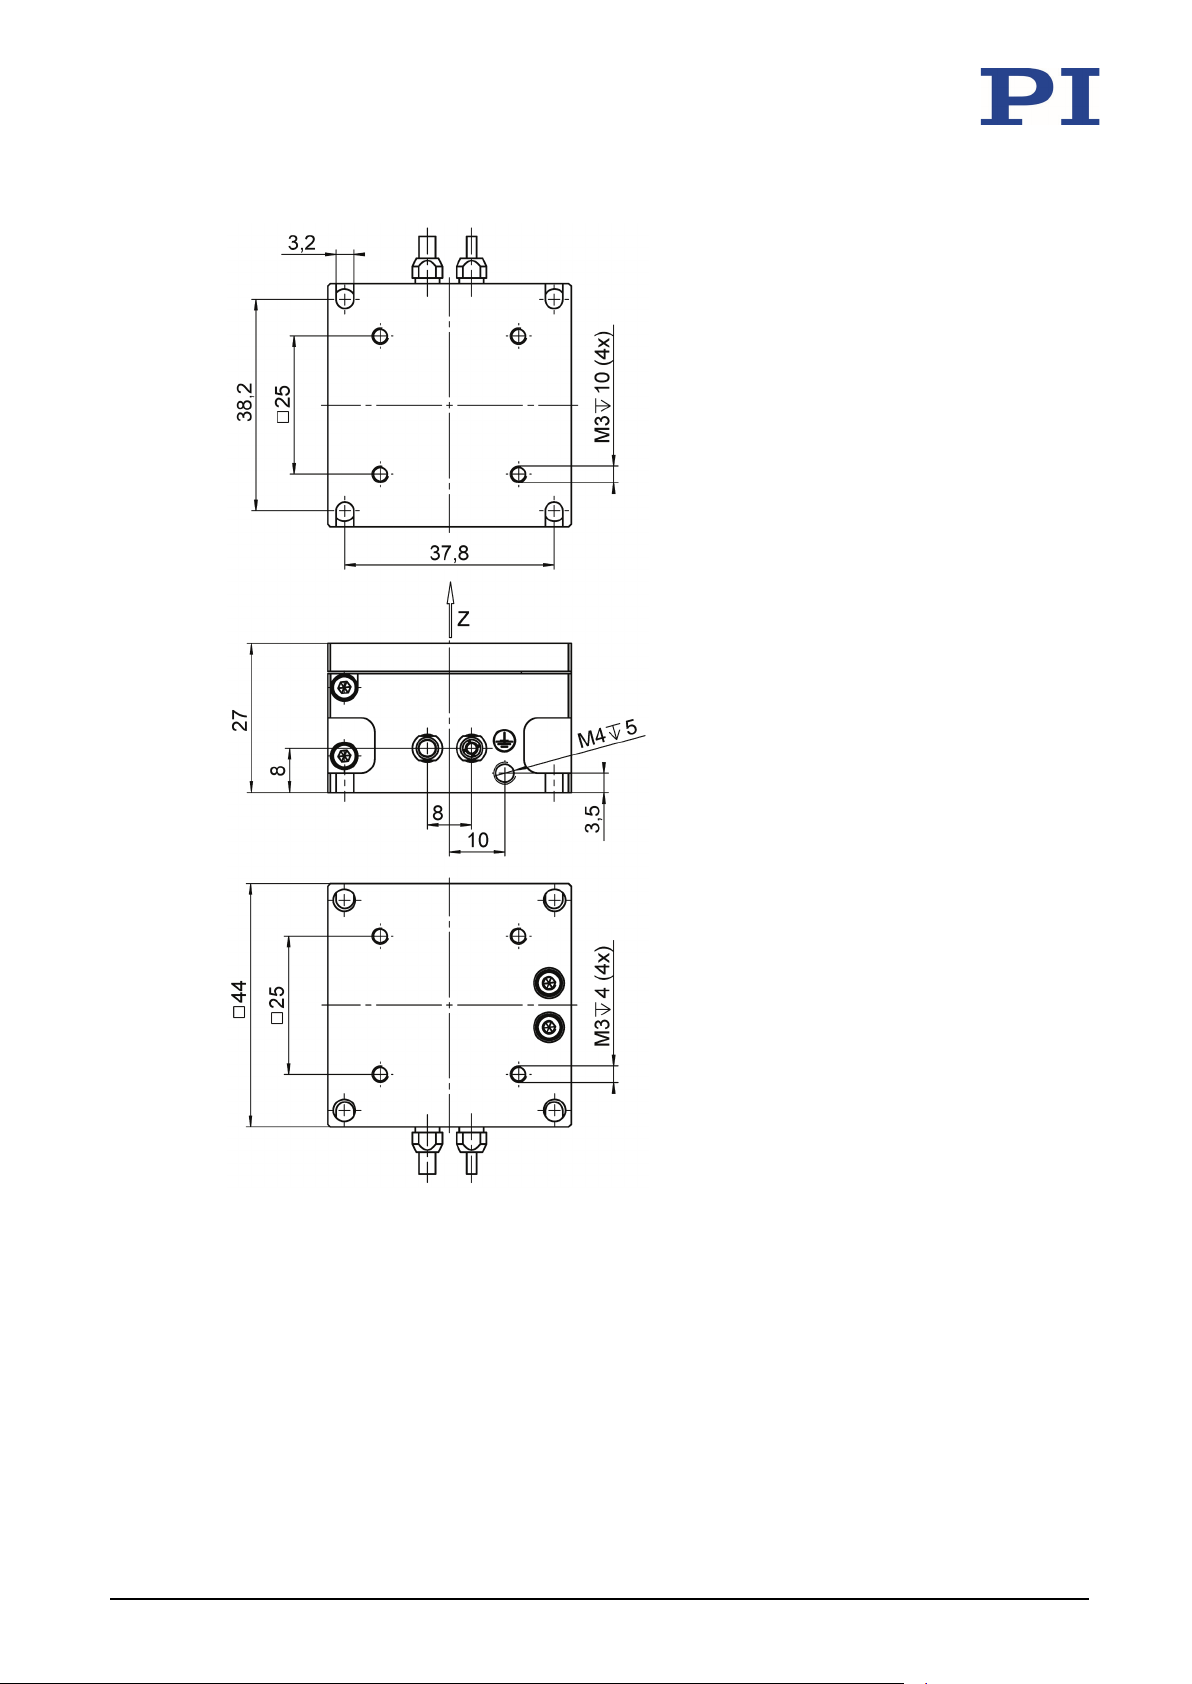
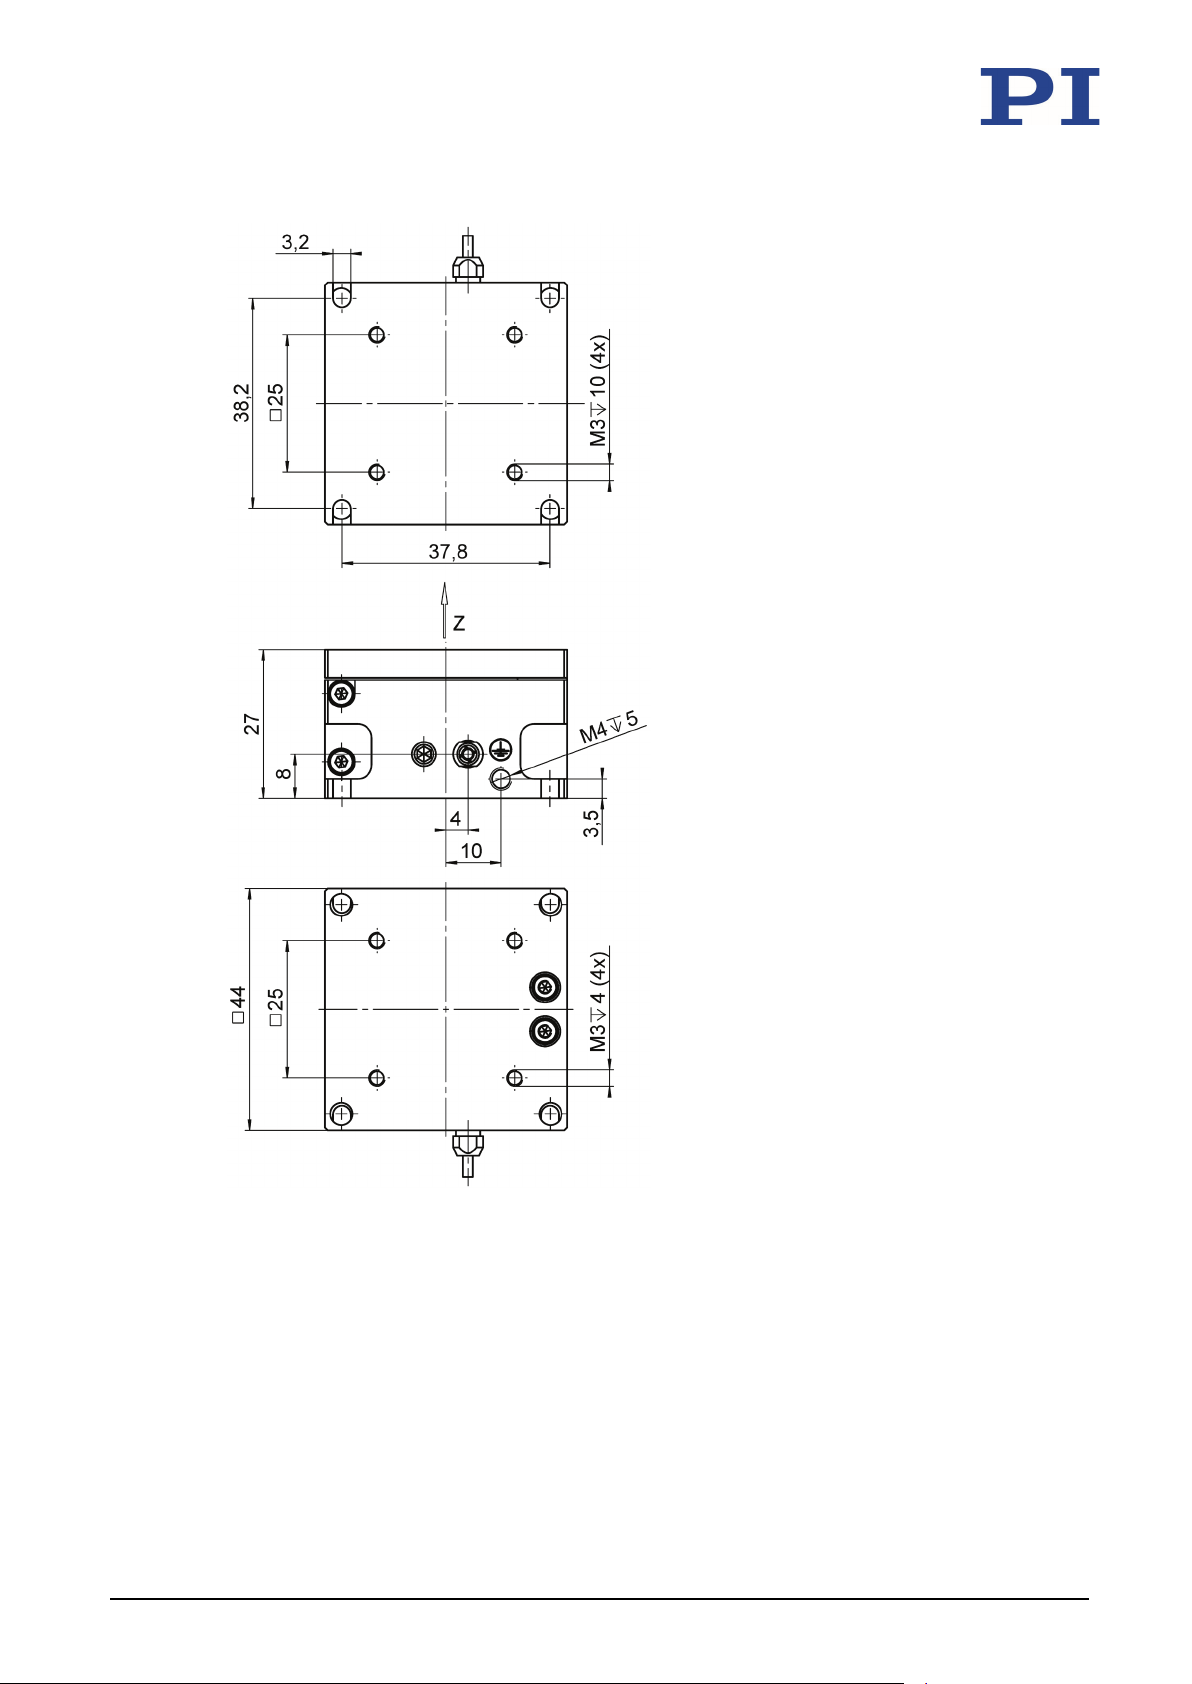
10.2 Dimensions
Dimensions in mm. Note that a comma is used in the drawings instead of a decimal point.
P-611 Positioning Systems PZ253E Version: 1.1.0 41
Figure 10: P-611.1S
Page 46
10 Technical Data
42 Version: 1.1.0 PZ253E P-611 Positioning Systems
Figure 11: P-611.10
Page 47
10 Technical Data
P-611 Positioning Systems PZ253E Version: 1.1.0 43
Figure 12: P-611.2S and P-611.20
Page 48
10 Technical Data
44 Version: 1.1.0 PZ253E P-611 Positioning Systems
Figure 13: P-611.XZS and P-611.XZ0
Page 49
10 Technical Data
P-611.3OF
44
38.2
37.8
44.2
3 2 3.5
50
40
3.5
10
P-611.3SF
48
40
40
44.2
3 2 4.1
50
40
19
13
P-611 Positioning Systems PZ253E Version: 1.1.0 45
Figure 14: P-611.3O, P-611.3S, P-611.3OF and P-611.3SF
A B C D i F G H J K L
P-611.3O 44 38.2 37.8 43.2 - - 3.5 44 - 3.5 10
P-611.3S 44 38.2 37.8 43.2 - - 3.5 44 - 3.5 10
Page 50
10 Technical Data
46 Version: 1.1.0 PZ253E P-611 Positioning Systems
Figure 15: P-611.ZS
Page 51
10 Technical Data
P-611 Positioning Systems PZ253E Version: 1.1.0 47
Figure 16: P-611.Z0
Page 52
10 Technical Data
10.3 Torque for Stainless Steel Screws (A2-70)
Screw size Minimum torque Maximum torque
M6 4 Nm 6 Nm
M5 2.5 Nm 3.5 Nm
M4 1.5 Nm 2.5 Nm
M3 0.8 Nm 1.1 Nm
M2.5 0.3 Nm 0.4 Nm
M2 0.15 Nm 0.2 Nm
M1.6 0.06 Nm 0.12 Nm
10.4 Pin Assignment
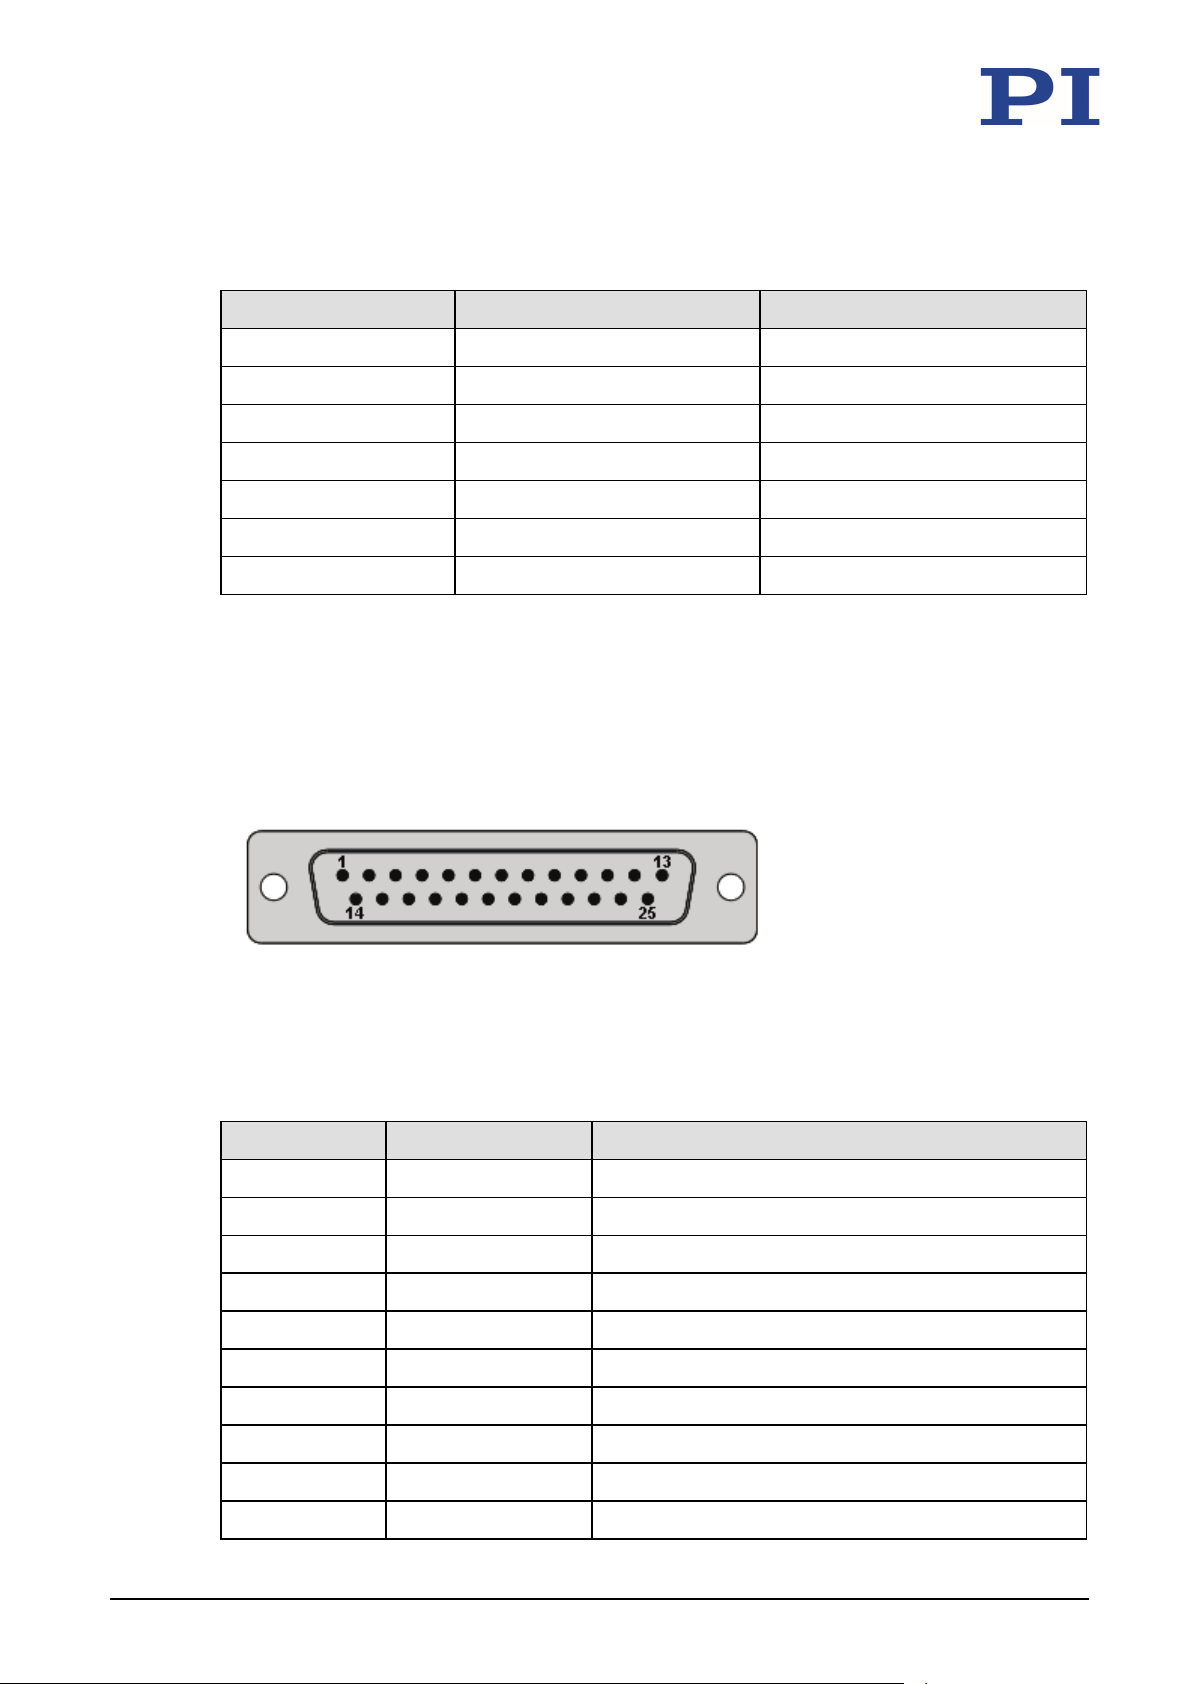
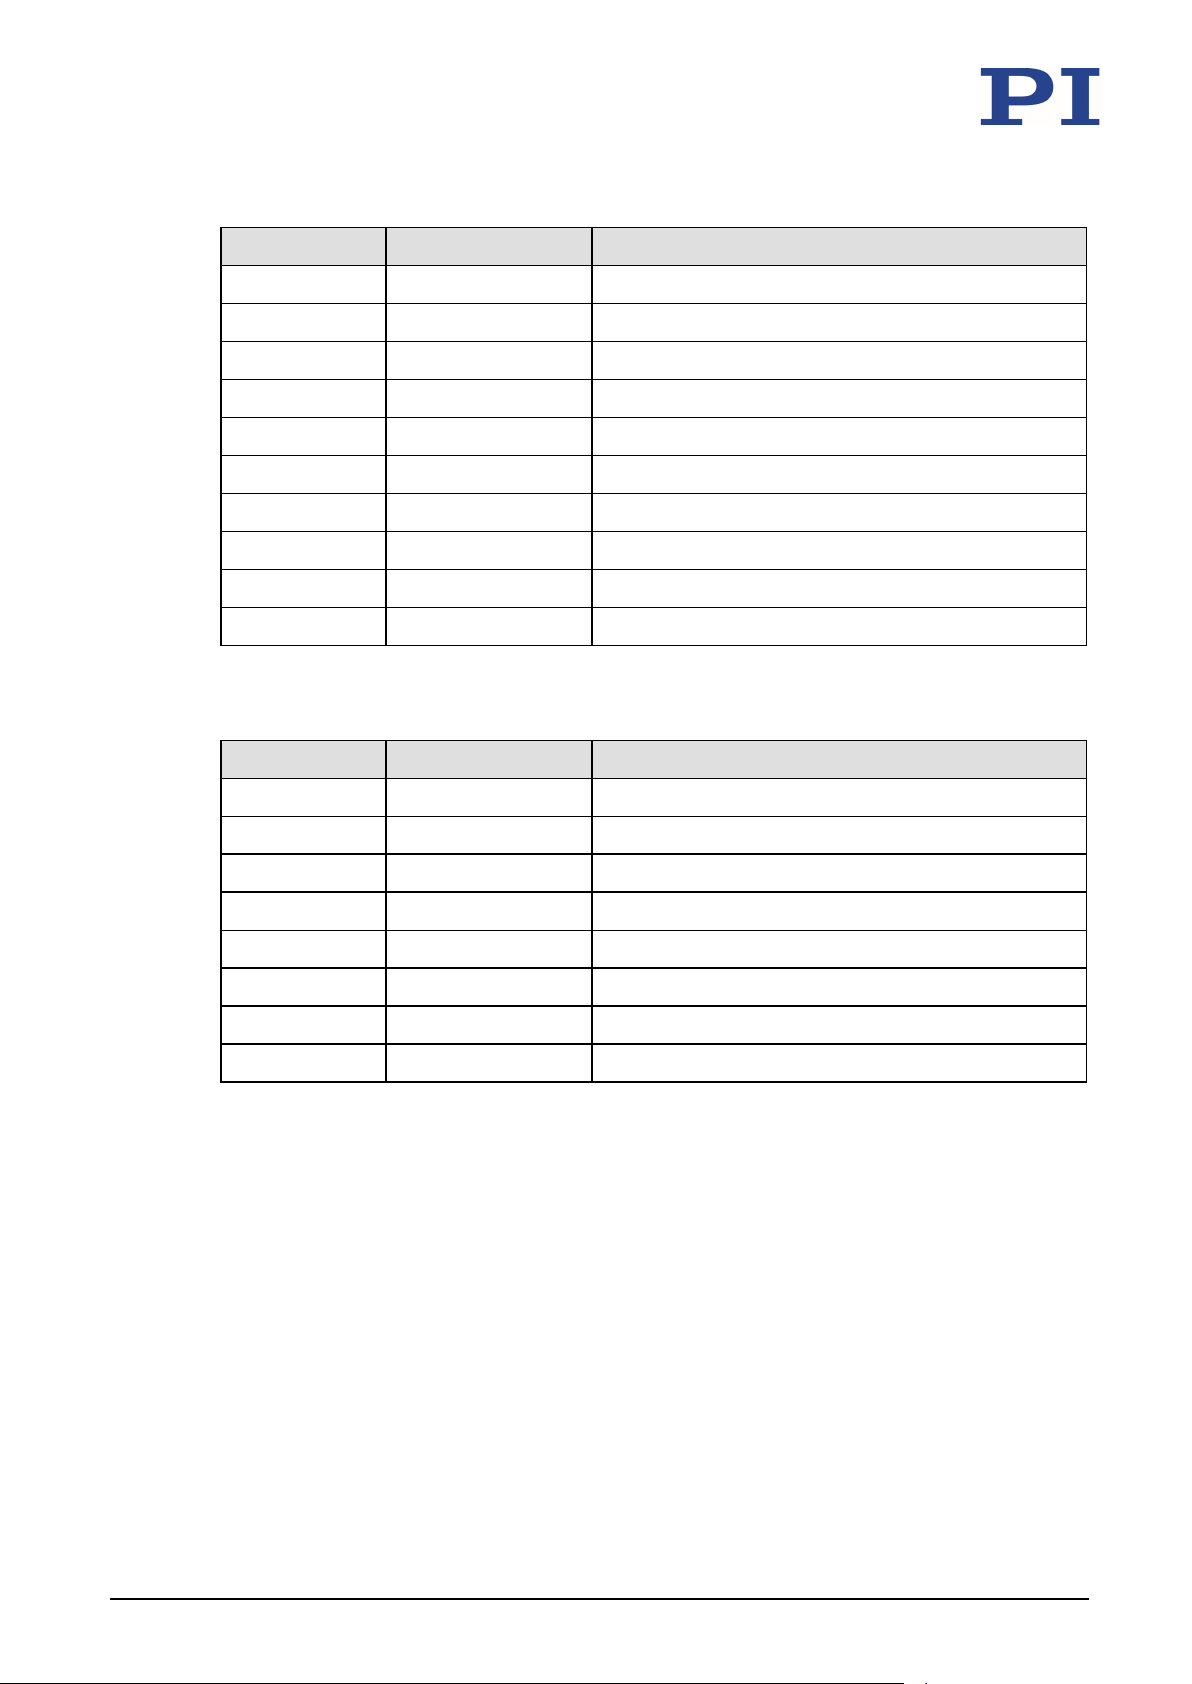
D-sub 25 connector
For P-611.3S/.3SF/.3O/.3OF only:
Figure 17: D-sub 25 connector: Front with connections
D-sub 25 connector pin assignment for the P-611.3S/.3SF
Pin Signal Function
1 Output SGS 3-B1 sensor signal
48 Version: 1.1.0 PZ253E P-611 Positioning Systems
2 Input SGS 3 reference voltage
3 Output SGS 2-B1 sensor signal
4 Input SGS 2 reference voltage
5 Output SGS 1-B1 sensor signal
6 Input SGS 1 reference voltage
7 to 10 Free ---
11 Input Piezo voltage +, channel 3
12 Input Piezo voltage +, channel 2
13 Input Piezo voltage +, channel 1
Page 53
10 Technical Data
Pin Signal Function
14 Output SGS 3-B2 sensor signal
15 GND SGS 3 GND
16 Output SGS 2-B2 sensor signal
17 GND SGS 2 GND
18 Output SGS 1-B2 sensor signal
19 GND SGS 1 GND
20 to 22 Free ---
23 Input Piezo voltage –, channel 3
24 Input Piezo voltage –, channel 2
25 Input Piezo voltage –, channel 1
D-sub 25 connector pin assignment for the P-611.3O/.3OF
Pin Signal Function
1 to 10 Free ---
11 Input Piezo voltage +, channel 3
12 Input Piezo voltage +, channel 2
13 Input Piezo voltage +, channel 1
14 to 22 Free ---
23 Input Piezo voltage –, channel 3
24 Input Piezo voltage –, channel 2
25 Input Piezo voltage –, channel 1
P-611 Positioning Systems PZ253E Version: 1.1.0 49
Page 54
10 Technical Data
.1S / .10
PZT Inner
Input
Piezo voltage
Ground
.1S / .2S /
SGS
1
Input
Supply voltage for strain
Cable
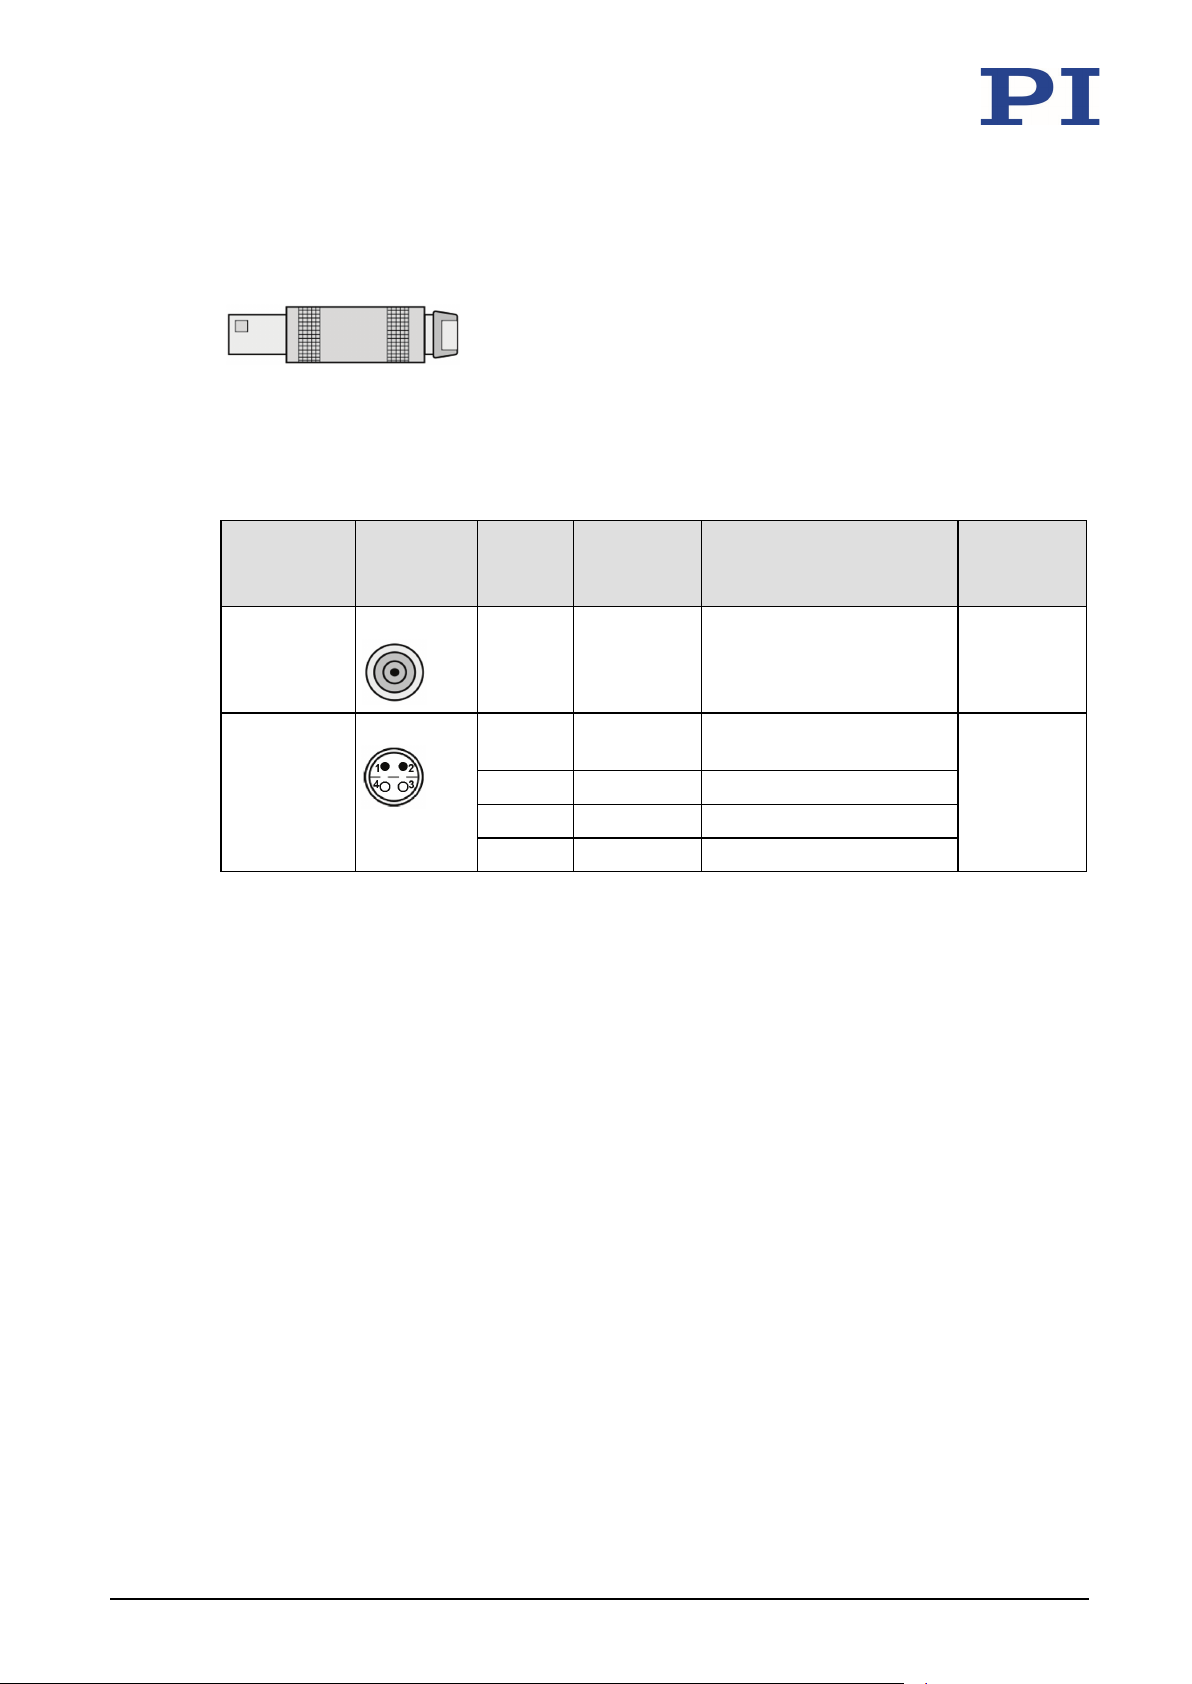
LEMO connectors
Only for P-611.1S/.10/.2S/.20/.XZS/.XZ0/.ZS/.Z0
Figure 18: LEMO connector (side view)
LEMO connectors according to model (one connector per axis)
P-611
model
.2S / .20
.XZS / .XZ0
.ZS / .Z0
.XZS / .ZS
Connector
(front
view)
Pin Signal Function Connector
shell
connecto
r
2 Output Sensor signal 1
3 Output Sensor signal 2
4 GND Supply voltage ground
–20 to 120 V
gauge sensor
shield
50 Version: 1.1.0 PZ253E P-611 Positioning Systems
Page 55
11 Old Equipment Disposal
11
Old Equipment Disposal
In accordance with EU law, electrical and electronic equipment may not be disposed of in EU
member states via the municipal residual waste.
Dispose of your old equipment according to international, national, and local rules and
regulations.
In order to fulfil its responsibility as the product manufacturer, Physik Instrumente (PI) GmbH &
Co. KG undertakes environmentally correct disposal of all old PI equipment made available on
the market after 13 August 2005 without charge.
Any old PI equipment can be sent free of charge to the following address:
Physik Instrumente (PI) GmbH & Co. KG
Auf der Roemerstr. 1
D-76228 Karlsruhe, Germany
P-611 Positioning Systems PZ253E Version: 1.1.0 51
Page 56
Page 57
12 EU Declaration of Conformity
12
EU Declaration of Conformity
For the P-611, an EU Declaration of Conformity has been issued in accordance with the
following European directives:
Low Voltage Directive
EMC Directive
RoHS Directive
The applied standards certifying the conformity are listed below.
Safety (Low Voltage Directive): EN 61010-1
EMC: EN 61326-1
RoHS: EN 50581
P-611 Positioning Systems PZ253E Version: 1.1.0 53
 Loading...