

Page 1
PI miCos GmbH, Freiburger Strasse 30, 79427 Eschbach, Germany
MP186E
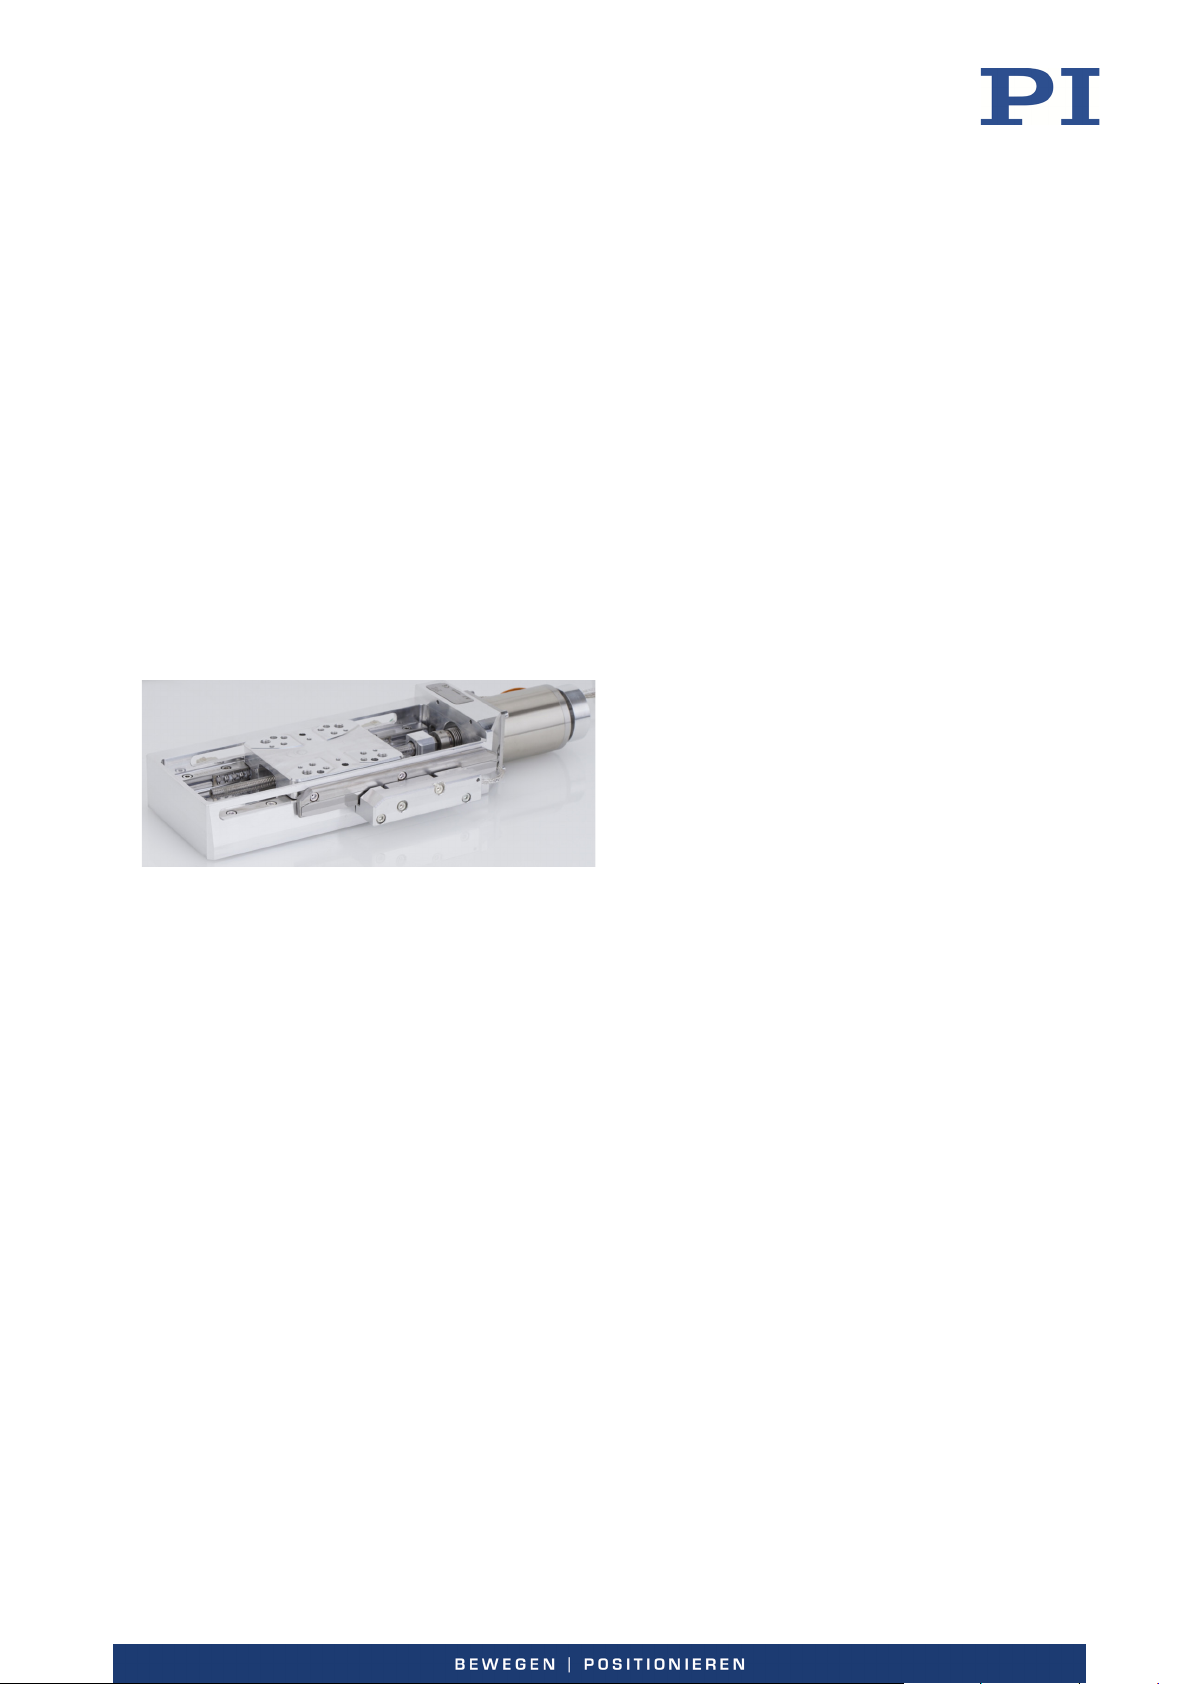
L
Vacuum
User Manual
Version: 1.0.0
Date: 2019-03-18
This document describes the following precision
linear
vacuum
x stands for travel range:
2
3 =
5 =
-509
-Compatible Precision Linear Positioner (1E-7 hPa)
positioner,
-compatible 1 E-7 hPa:
L-509.0x1300V7:
with 2-phase stepper motor, without encoder
L-509.0x1311V7:
with 2-phase stepper motor and linear encoder
= 26 mm
52 mm
102 mm
Phone +49 7634 5057-0, Fax +49 7634 5057-99, Email [email protected], www.pi.ws
Page 2
The following company names and brands are registered trademarks of
Physik Instrumente (PI) GmbH & Co. KG:
PI®, PIC®, NanoCube®, PICMA®, PIFOC®, PILine®, NEXLINE®, PiezoWalk®, PicoCube®, PiezoMove®,
PIMikroMove®, NEXACT®, Picoactuator®, PInano®, NEXSHIFT®, PITOUCH®, PIMag®, PIHera, Q-Motion®
© 2019 Physik Instrumente (PI) GmbH & Co. KG, Karlsruhe, Germany. The text, photographs, and drawings in
this manual are protected by copyright. With regard thereto, Physik Instrumente (PI) GmbH & Co. KG reserves
all rights. The use of any text, images and drawings is permitted only in part and only when indicating the
source.
Original Instructions
First printing: 18-MAR-2019
Document number: MP186E, MMa, Version 1.0.0
Subject to change. This manual is superseded by any new release. The latest release is available for download
from our website (p. 3).
Page 3
Contents
1 About this Document 1
1.1 Objective and Target Group of this User Manual ...................................................... 1
1.2 Symbols and Typographic Conventions...................................................................... 1
1.3 Definition of Terms ..................................................................................................... 2
1.4 Pictures ....................................................................................................................... 2
1.5 Other Applicable Documents ..................................................................................... 2
1.6 Downloading Manuals ................................................................................................ 3
2 Safety 5
2.1 Intended Use .............................................................................................................. 5
2.2 General Safety Instructions ........................................................................................ 5
2.3 Organizational Measures ............................................................................................ 5
2.4 Measures for Handling Vacuum-Compatible Products .............................................. 6
3 Product Description 7
3.1 Model Overview ......................................................................................................... 7
3.2 Product View .............................................................................................................. 9
3.3 Direction of Motion .................................................................................................... 9
3.4 Product Labeling ....................................................................................................... 10
3.5 Scope of Delivery ...................................................................................................... 11
3.6 Accessories ............................................................................................................... 11
3.7 Suitable Controllers .................................................................................................. 12
3.8 Technical Features .................................................................................................... 12
3.8.1 Encoder ........................................................................................................ 12
3.8.2 Limit Switches .............................................................................................. 12
4 Unpacking 13
5 Installation 15
5.1 General Notes on Installation ................................................................................... 15
5.2 Attaching the L-509 to a Surface .............................................................................. 17
5.3 Connecting the L-509 to the Protective Earth Conductor ........................................ 20
5.4 Affixing the Load to the L-509 .................................................................................. 22
5.5 Connecting the L-509 to a Controller ....................................................................... 24
6 Startup 25
6.1 General Notes on Start-Up ....................................................................................... 25
6.2 Starting up the Positioner ........................................................................................ 28
6.2.1 L-509 Entries in the Positioner Database of PI ............................................ 28
Page 4
7 Maintenance 29
7.1 General Notes on Maintenance ............................................................................... 29
7.2 Performing a Maintenance Run ............................................................................... 29
7.3 Cleaning the L-509 .................................................................................................... 30
8 Troubleshooting 31
8.1 Possible Causes and Remedies ................................................................................. 31
8.2 Moving the Platform Manually ................................................................................ 33
9 Customer Service Department 35
10 Technical Data 37
10.1 Specifications ............................................................................................................ 37
10.1.1 Data Table .................................................................................................... 37
10.1.2 Maximum Ratings ........................................................................................ 38
10.1.3 Ambient Conditions and Classifications ...................................................... 38
10.2 Dimensions ............................................................................................................... 39
10.2.1 L-509 Positioner ........................................................................................... 39
10.2.2 Hole Pattern of the Platform of the L-509 ................................................... 40
10.2.3 L-500.AV3-V9 Adapter Bracket .................................................................... 41
10.3 Tightening Torque for Screws, ISO 4762 - A2 ........................................................... 42
10.4 Pin Assignment ......................................................................................................... 43
10.4.1 D-Sub 15 (Female) ....................................................................................... 43
10.4.2 D-Sub 9 (Female, Only L 509.0x1311V7) ..................................................... 44
11 Old Equipment Disposal 45
12 EU Declaration of Conformity 47
Page 5
1 About this Document
1
About this Document
1.1 Objective and Target Group of this User Manual
This user manual contains the required information on the intended use of the L-509 (10-7 hPa
vacuum version).
Basic knowledge of closed-loop systems, motion control concepts, handling vacuum products,
and suitable cleanliness and safety measures is assumed.
The latest versions of the user manuals are available for download on our website (page 3).
1.2 Symbols and Typographic Conventions
The following symbols and typographic conventions are used in this user manual:
NOTICE
CAUTION
Dangerous situation
If not avoided, the dangerous situation will result in minor injury.
Actions to take to avoid the risk.
Dangerous situation
If not avoided, the dangerous situation will result in damage to equipment.
Actions to take to avoid the risk.
INFORMATION
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 1
Information for easier handling, tricks, tips, etc.
Page 6
1 About this Document
Warning sign affixed to the product that refers to detailed information
Symbol/
Label
1.
2.
Meaning
Action consisting of several steps whose sequential order must be
observed
Action consisting of one or several steps whose sequential order is
irrelevant
Lists
p. 5 Cross-reference to page 5
RS-232 Labeling of an operating element on the product (example: socket of
the RS-232 interface)
in this manual.
1.3 Definition of Terms
Term Explanation
Load capacity Maximum load capacity in the vertical direction when the positioner is
mounted horizontally. The contact point of the load is in the center of
the platform.
Max. push/pull force Maximum force effective in the direction of motion.
In the case of vertical mounting, the specified value (see 37) only
applies when the servo mode is on.
Linear encoder The linear encoder is a sensor here used for detecting the current
position of the platform. For enhanced accuracy, a mechanical
connection of the sensor system and the platform is applied.
1.4 Pictures
For better understandability, the colors, proportions and degree of detail in illustrations can
deviate from the actual circumstances. Photographic illustrations may also differ and must not
be seen as guaranteed properties.
1.5 Other Applicable Documents
The devices and software tools from PI that are mentioned in this documentation are described
in separate manuals.
Product Document
Positioners with electric motors MP146EK Short instructions for positioners with
electric motors
C-663.11 stepper motor controller MS208E User Manual
SMC Hydra motion controller Hardware Manual
2 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 7
1 About this Document
isplayed on the website after
1.6 Downloading Manuals
INFORMATION
If a manual is missing or problems occur with downloading:
Contact our customer service department (p. 35).
INFORMATION
For products that are supplied with software (CD in the scope of delivery), access to the
manuals is protected by a password. Protected manuals are only d
entering the password.
The password is included on the CD of the product.
For products with CD: Identify the password
1. Insert the product CD into the PC drive.
2. Switch to the Manuals directory on the CD.
3. In the Manuals directory, open the Release News (file including releasenews in the file
name).
4. Find the user name and the password in the section "User login for software download"
in the Release News.
Downloading Manuals
1. Open the website http://www.pi.ws.
2. Click Info.
3. If you have a user name and password:
a) Click Login.
b) Log in with the user name and password.
4. Click >> Product Downloads.
5. In the Product Files area, click the corresponding product category.
6. On the right-hand side of the page, select the corresponding subcategory.
7. Navigate to the product number on the page.
The following manuals are displayed:
− Freely accessible manuals
− Manuals that are protected by a password
8. Click the desired manual and save it to the hard disk of your PC or to a data storage
medium.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 3
Page 8
Page 9
2 Safety
2
Safety
2.1 Intended Use
The L-509 is a laboratory device as defined by DIN EN 61010. It is intended for indoor use and
use in an environment which is free of dirt, oil, and lubricants. Because cleanliness is important
for a vacuum product, it is also necessary to take various measures to avoid contamination. In
particular, gloves specially designed for handling products must be worn and the product may
only be stored packed in air-tight original packaging or otherwise cleanroom-compatible
packaging, in a cleanroom environment or in vacuum chambers see also chapter 4 "Unpacking"
p. 13).
In accordance with its design, the L-509 is intended for single-axis positioning, adjusting and
shifting of loads at different velocities. The L-509 is not intended for applications in areas, in
which a failure would present severe risks to human beings or the environment.
The L-509 is intended for horizontal or vertical mounting. For the load limits with vertical
mounting, see "General Notes on Installation". (p. 15).
The intended use of the L-509 is only possible when completely mounted and connected.
The L-509 must be operated with a suitable controller (p. 12). The controller is not included in
the scope of delivery of the L-509.
2.2 General Safety Instructions
The L-509 is built according to state-of-the-art technology and recognized safety standards.
Improper use of the L-509 may result in personal injury and/or damage to the L-509.
Only use the L-509 for its intended purpose, and only use it if it is in perfect condition.
Read the user manual.
Immediately eliminate any faults and malfunctions that are likely to affect safety.
The operator is responsible for correct installation and operation of the L-509.
2.3 Organizational Measures
User Manual
Always keep this user manual available when using the L-509.
The latest versions of the user manuals are available on our website (p. 3) for
download.
Add all information from the manufacturer such as supplements or technical notes to
the user manual.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 5
Page 10
2 Safety
If you give the L-509 to other users, also include this user manual as well as all other
relevant information provided by the manufacturer.
Only use the device on the basis of the complete user manual. Missing information due
to an incomplete user manual can result in minor injury and damage to equipment.
Only install and operate the L-509 after you have read and understood this user
manual.
Personnel Qualification
The L-509 may only be installed, started up, operated, maintained, and cleaned by authorized
and appropriately qualified personnel.
2.4 Measures for Handling Vacuum-Compatible Products
When handling the vacuum version of the positioner, attention must be paid to appropriate
cleanliness. At PI, all parts are cleaned before assembly. During assembly and measurement,
powder-free gloves are worn. In addition, the products are wiped clean once again and then
shrink-wrapped twice in vacuum-compatible film.
Only touch the positioner when wearing powder-free gloves.
If necessary, wipe the positioner clean after unpacking.
6 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 11
3 Product Description
3
Product Description
3.1 Model Overview
Classification of the positioners
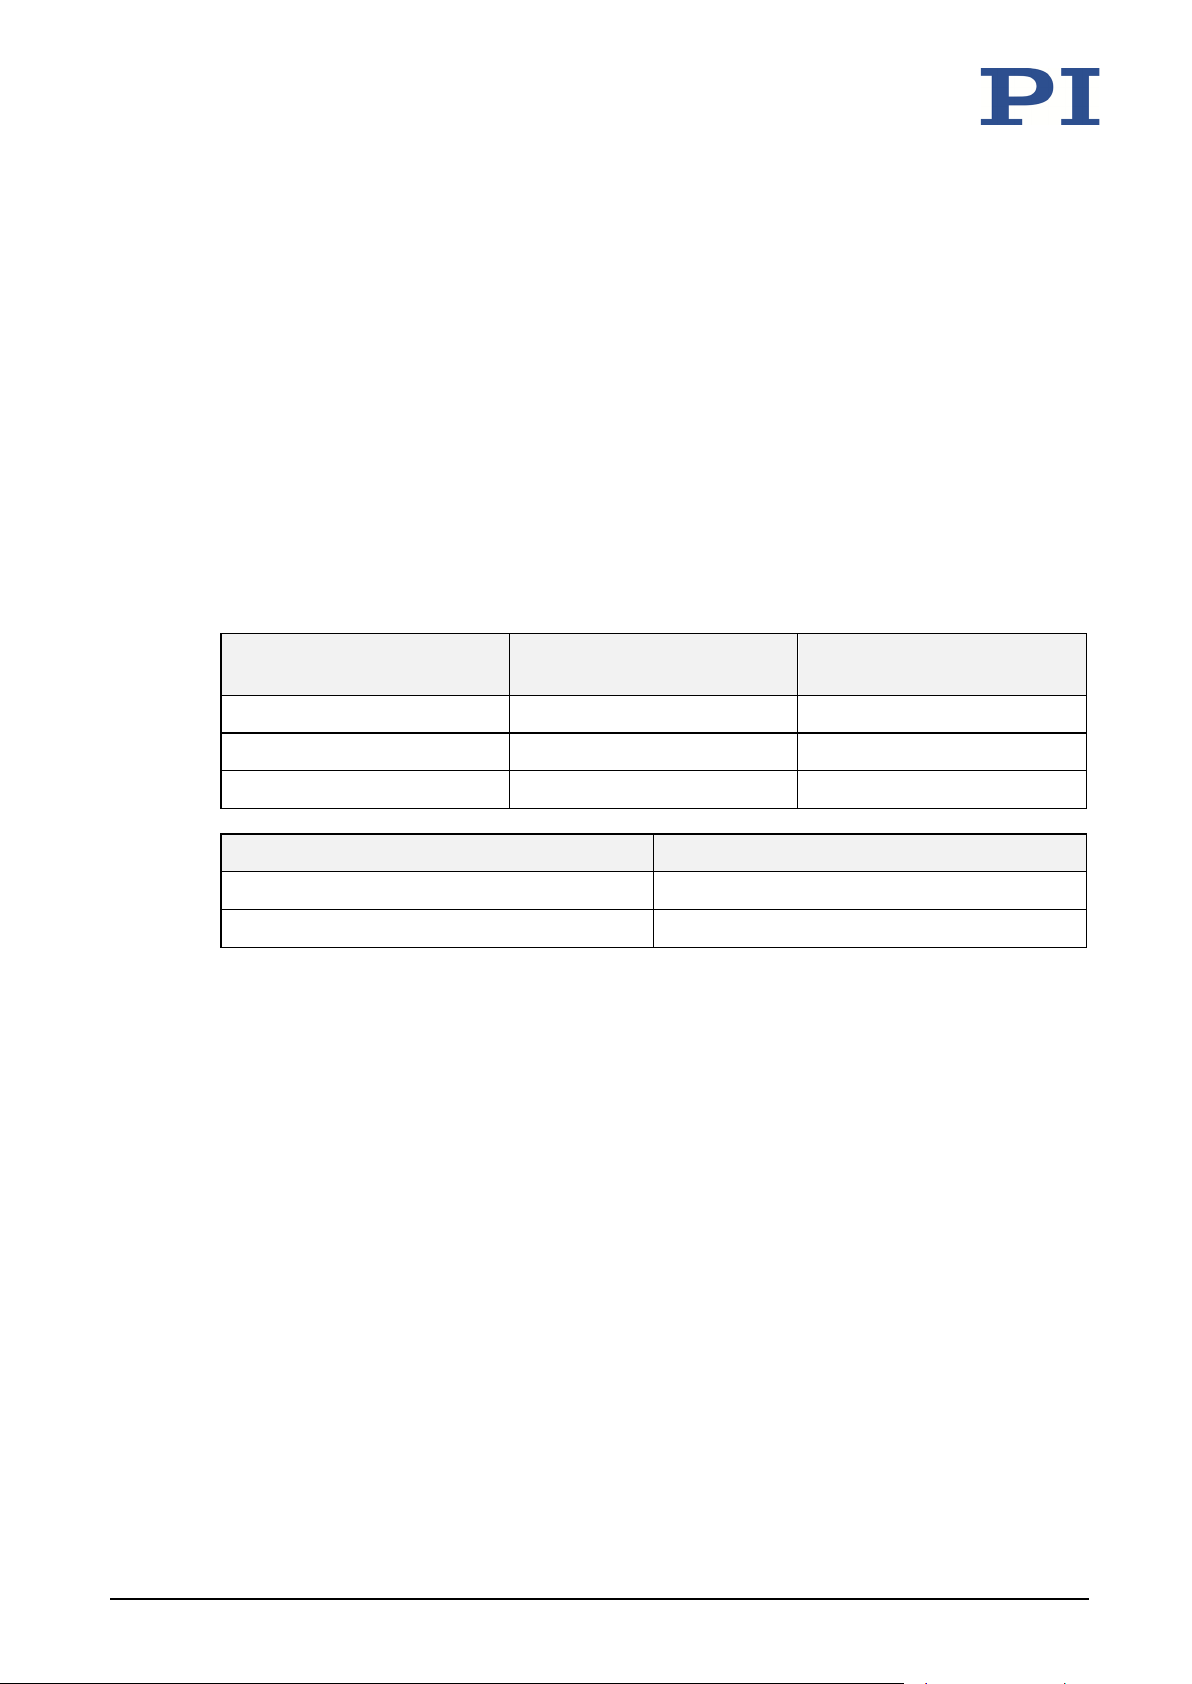
All models are electromotive linear positioning positioners with precision leadscrew. They differ
with respect to:
Travel range
Encoder equipment
L-509 Travel range in mm
.02xxxxV7 26 1
.03xxxxV7 52 2
.05xxxxV7 102 4
L-509 Linear encoder
.0x1300V7
.0x1311V7* +
* Separate sensor connection
Travel range in inches
(approx.)
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 7
Page 12
3 Product Description
Detailed model overview
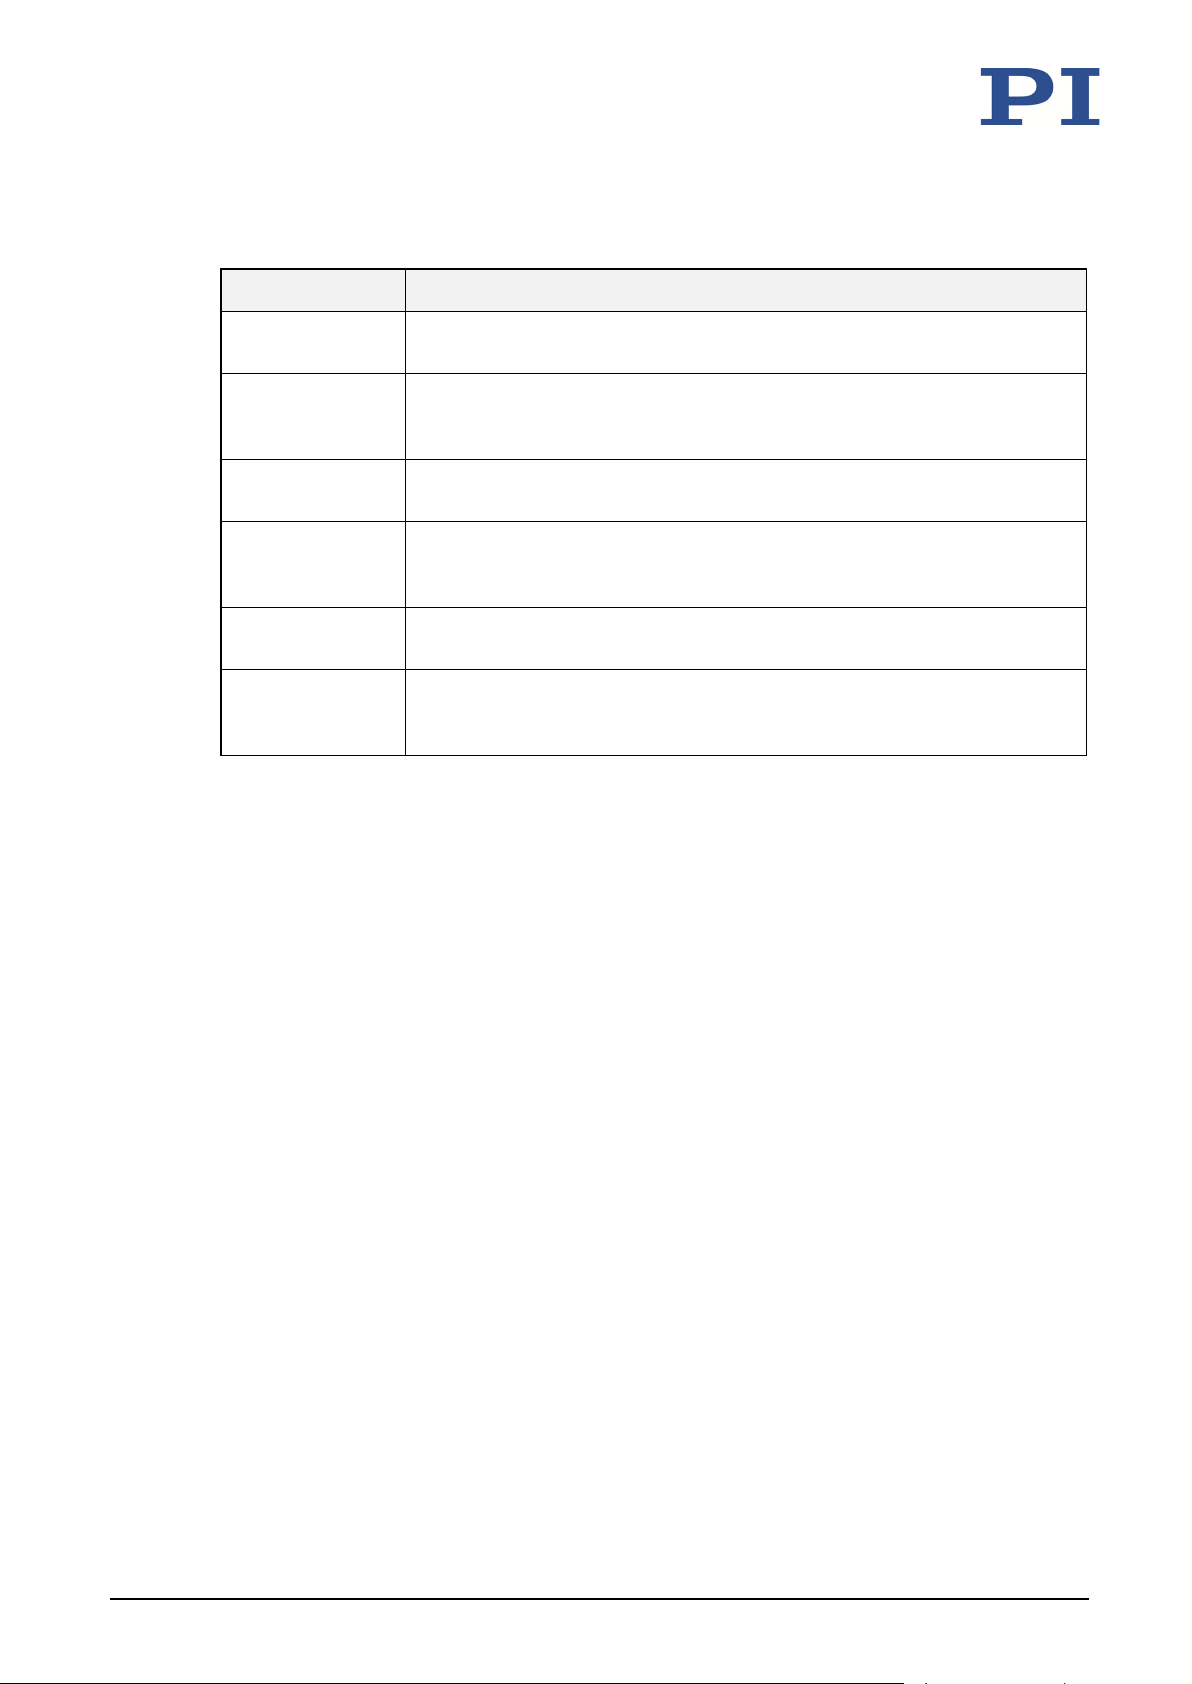
Order number Product name
L-509.021300V7 Precision linear positioner, 85 mm width, 2-phase stepper motor, 26 mm
(1") travel range, mechanical limit switches, vacuum-compatible 1 E-7 hPa
L-509.021311V7 Precision linear positioner, 85 mm width, 2-phase stepper motor, 26 mm
(1") travel range, linear encoder with sin/cos signal transmission,
mechanical limit switches, vacuum-compatible 1 E-7 hPa
L-509.031300V7 Precision linear positioner, 85 mm width, 2-phase stepper motor, 52 mm
(2") travel range, mechanical limit switches, vacuum-compatible 1 E-7 hPa
L-509.031311V7 Precision linear positioner, 85 mm width, 2-phase stepper motor, 52 mm
(2") travel range, linear encoder with sin/cos signal transmission,
mechanical limit switches, vacuum-compatible 1 E-7 hPa
L-509.051300V7 Precision linear positioner, 85 mm width, 2-phase stepper motor, 102 mm
(4") travel range, mechanical limit switches, vacuum-compatible 1 E-7 hPa
L-509.051311V7 Precision linear positioner, 85 mm width, 2-phase stepper motor, 102 mm
(4") travel range, linear encoder with sin/cos signal transmission,
mechanical limit switches, vacuum-compatible 1 E-7 hPa
For further technical data, see the specifications. (p. 37).
8 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 13
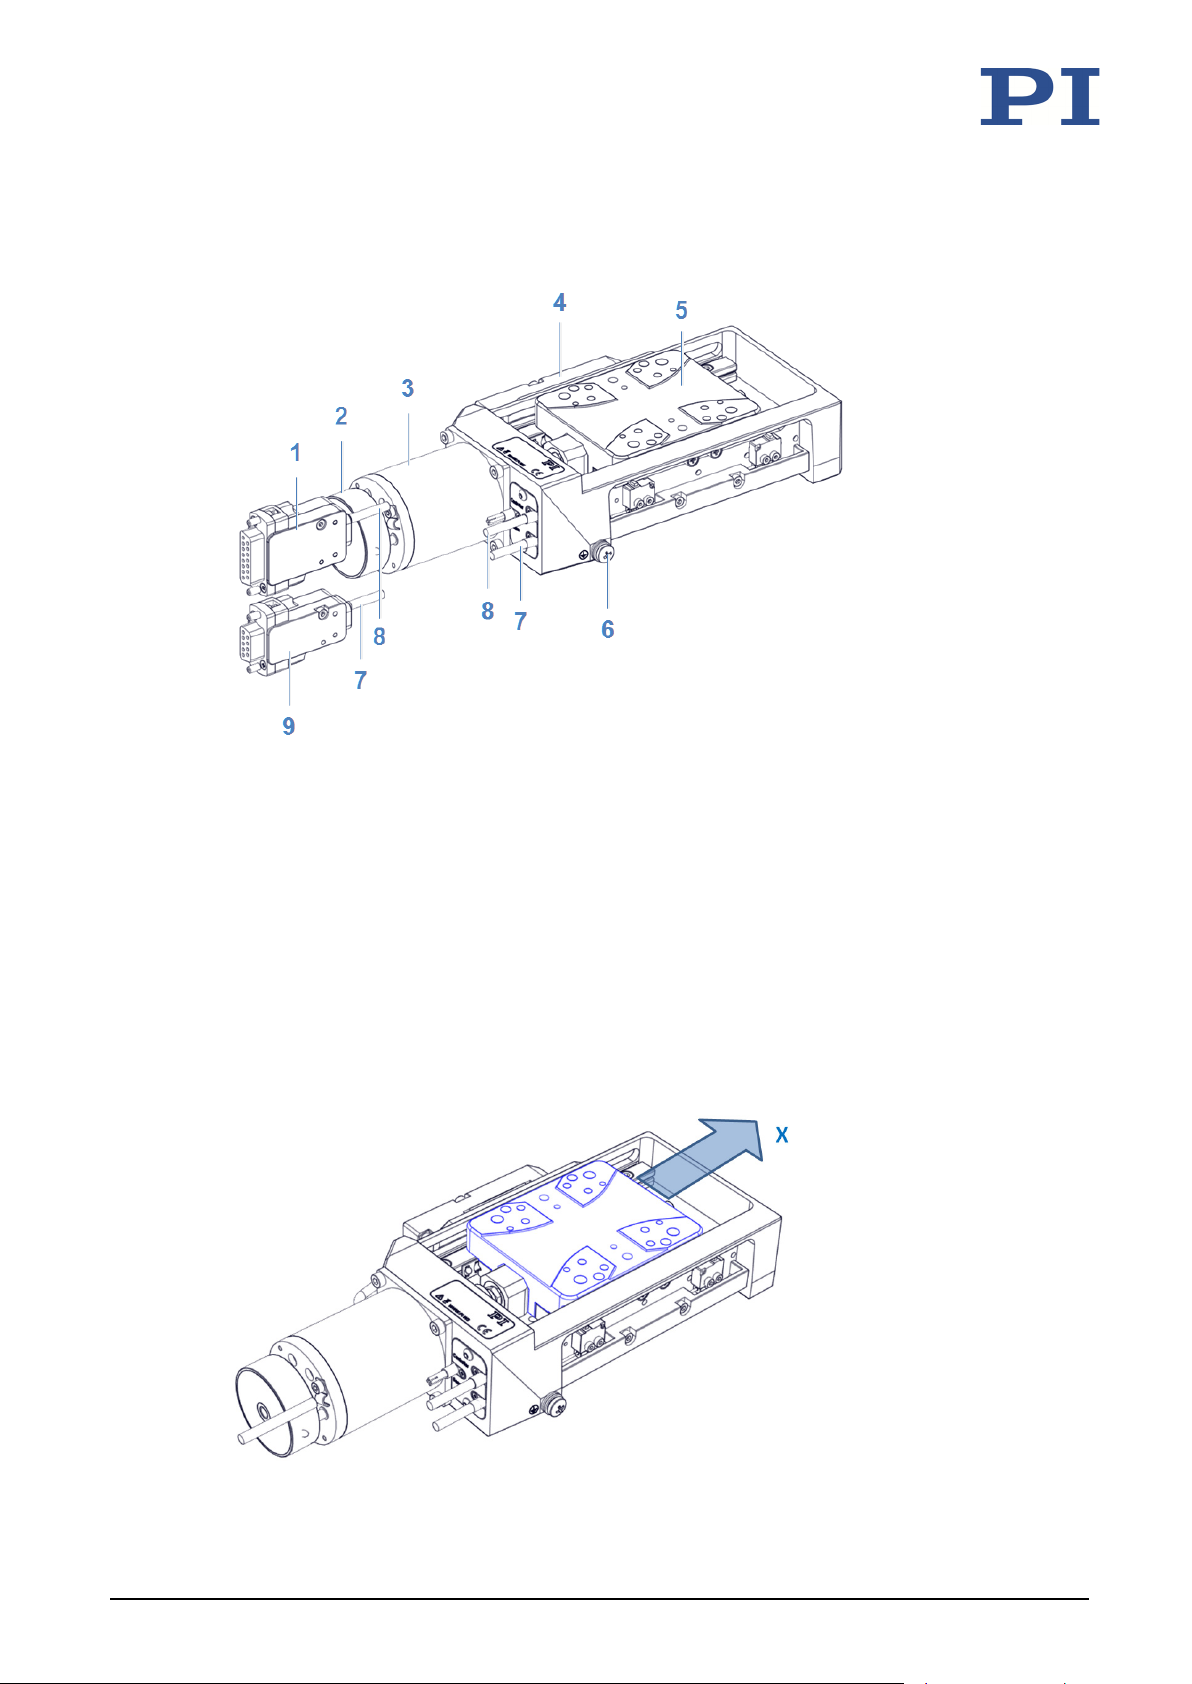
3 Product Description
3.2 Product View
Figure 1: Parts of the positioner (sample, schematic)
1 Motor connector (vacuum-capable plug HD D-Sub 26)
2 Vibration absorber
3 Motor
4 Sensor unit (L-509.0x1311V7 models only)
5 Platform
6 Protective earth (PE) connector (screw M4 with corresponding washers)
7 Sensor wire strands (vacuum-capable; not shown in their entireties)
8 Motor wire strands (vacuum-capable; not shown in their entireties)
9 Sensor connector (vacuum-capable plug D-Sub 9; L-509.0x1311V7 models only)
3.3 Direction of Motion
Figure 2: Direction of motion of the platform
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 9
X (arrow direction:) Direction of motion on positive command
Page 14
3 Product Description
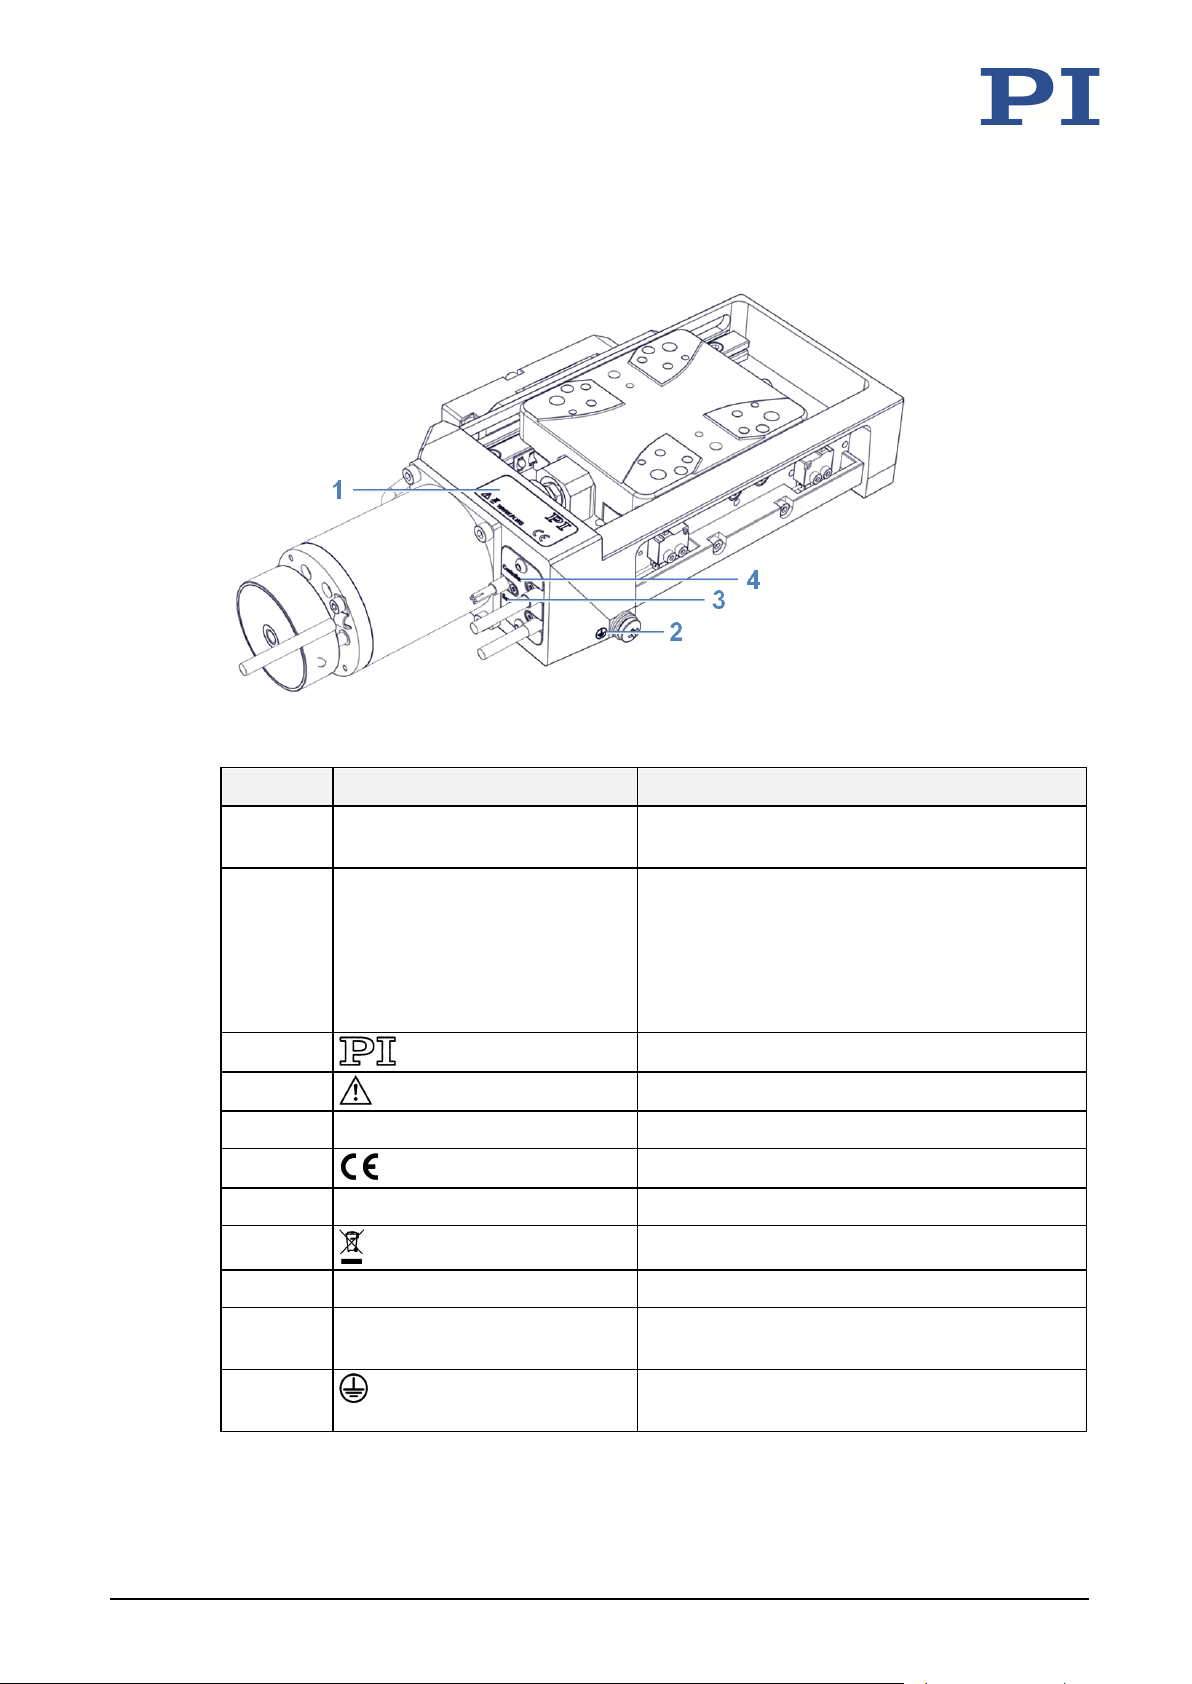
3.4 Product Labeling
Figure 3: Product labeling
Position Labeling Description
1 L-509.031300V7 Product name (example), the characters after
the period refer to the model
1 417002159 Serial number (example), individual for each
L-509
Meaning of the places (counting from left):
1 = internal information,
2 and 3 = year of manufacture,
4 to 9 = consecutive numbers
1
1
Manufacturer's logo
Warning sign "Observe manual!"
1 Country of origin: Germany Country of origin
1
CE conformity mark
1 WWW.PI.WS Manufacturer's address (website)
1
Old equipment disposal
10 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
4 Controller Motor connection
3 Sensor Linear encoder connection (L-509.0x1311V7
models only)
2
Protective earth symbol, marks the protective
earth connection of the L-509 (p. 20)
Page 15
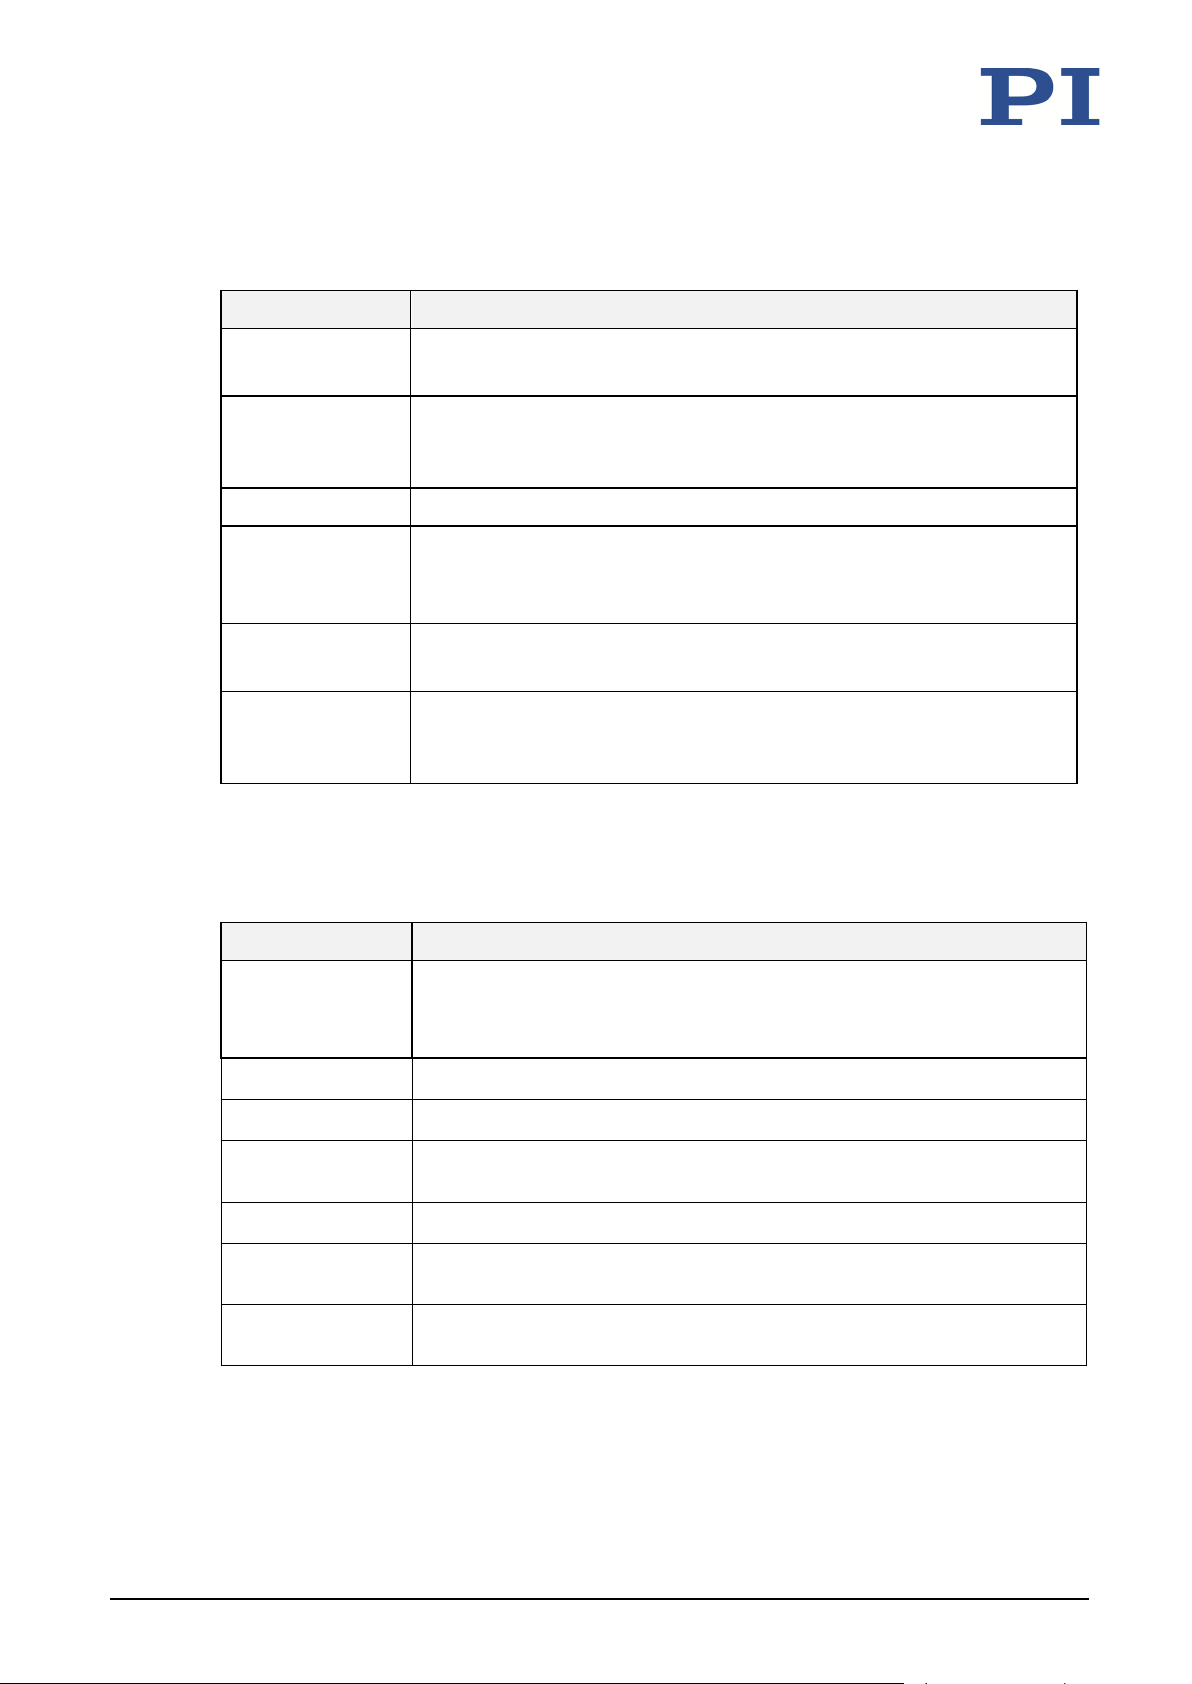
3 Product Description
3.5 Scope of Delivery
Item number Component
L-509.0x1300V7 or
L-509.0x1311V7
720090620-0300
(+ C-815.LSH2 /
C-815.AC32-0300)
MP146EK Short instructions for positioners with electric motors
62345138 Screw set for mounting the positioner
5604500041 Adapter for function tests outside the vacuum chamber
5604500044 (Only L-509.0x1311V7:)
* Corresponds to DIN 912 / ** Corresponds to DIN 7
3.6 Accessories
Positioner according to order (p. 7)
Motor cable and for L-509.0x1311V7: sensor cable3 m (if applicable incl.
A/D converter); according to the controller ordered
- 4 socket head screws, ISO 4762* M4x14
- 2 dowel pins, ISO 2338* - 4 m6 x 12
Adapter vacuum feedthrough D-Sub-15 with housing
Adapter for function tests outside the vacuum chamber
Adapter vacuum feedthrough D-Sub-9 with housing
Order number Item
L-500.AV3-V9 Mounting adapter for vertical mounting of L-509 positioners, incl.
- 3 socket head screws, ISO 4762* M6x12
- 2 dowel pins, ISO 2338** - 4 m6 x 12
C-815.VFU3 Vacuum feedthrough, 3x D-Sub 15 for customer's vacuum hole
C-815.VFU6 Vacuum feedthrough, 6x D-Sub 15 for customer's vacuum hole
C-815.VFU11 Vacuum feedthrough, 1x D-Sub 15 / 1x D-Sub 9 for customer's vacuum
hole
C-815.VFU15 Vacuum feedthrough, 15x D-Sub 15 for customer's vacuum hole
C-815.VFU33 Vacuum feedthrough, 3x D-Sub 15 / 3x D-Sub 9 for customer's vacuum
hole
C-815.VFU66 Vacuum feedthrough, 6x D-Sub 15 / 6x D-Sub 9 for customer's vacuum
hole
* Corresponds to DIN 912 / ** Corresponds to DIN 7
To order, contact the customer service department (p. 35).
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 11
Page 16
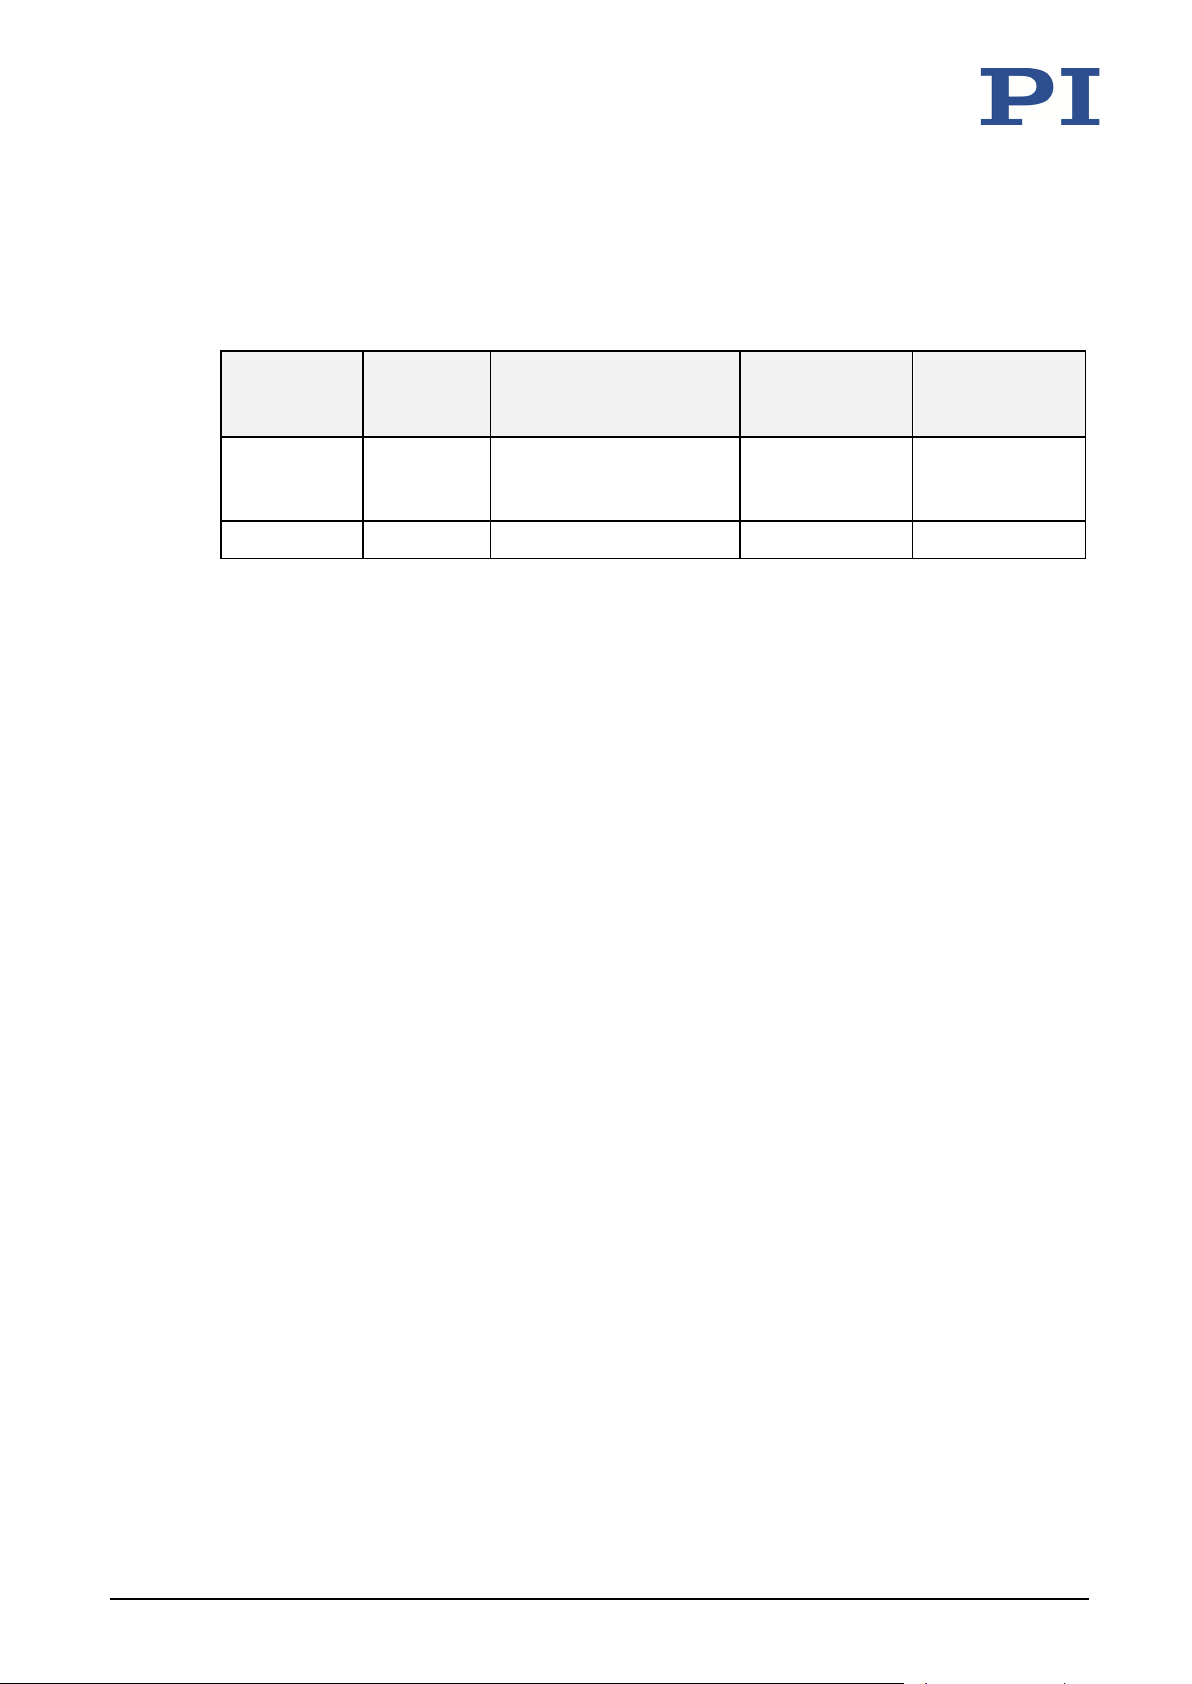
3 Product Description
3.7 Suitable Controllers
The L-509 must be connected to a suitable controller. The following controllers from PI are
suitable for the operation of the L-509:
Controller Axes per
controller
C-663 1 USB, RS-232, daisy chain
SMC Hydra 1 RS-232, LAN Yes L-509.0x1311V7
PC software is included in the scope of delivery of the controllers from PI. The operation of the
controllers is described in the corresponding user manuals.
3.8 Technical Features
3.8.1 Encoder
The L-509.0x1300V7 models are not equipped with an encoder.
Linear encoder
The L-509.0x1311V7 models are equipped with an optical linear encoder. For the encoder
resolution, refer to the table in the "Specifications" section (p. 37).
Optical linear encoders measure the actual position directly (direct metrology). Errors occurring
in the drive, such as nonlinearity, backlash or elastic deformations cannot influence the
measurement of the position.
PC interfaces Multiple
controllers on
the same PC
Yes, same
network
interface
Applicable
positioner
models
L-509.0x1300V7
3.8.2 Limit Switches
12 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
The L-509 is equipped with mechanical limit switches.
Each limit switch closes a contact on a dedicated line to the controller. The controller then stops
the motion. If the controller does not stop the motion in time, the positioner runs into the hard
stop.
Page 17
4 Unpacking
4
Unpacking
1. Remove the L-509 in its inner and outer bag from the transport packaging carefully.
Now unpack the L-509 carefully and according to the regulations on the label of the
packaging as follows:
2. Compare the contents with the items listed in the contract and the packing list.
3. Before opening the vacuum packaging, check the packaging and the product – if visible
– for signs of damage. If there is any sign of damage or missing parts, contact PI
immediately.
4. Clean the outer bag with a lint-free cleanroom cloth that has been dampened with
clean isopropyl alcohol (99.9% or better).
5. Remove the outer bag before bringing into the cleanroom area
6. Only open the inner bag in a cleanroom environment. Wear cleanroom gloves. After
removing the bag, the product should only be stored, air-tight wrapped in original
packaging or in other clean-room packaging, in a cleanbox, a cleanroom or in a sealed
vacuum chamber.
7. Touch the product only when wearing cleanroom gloves. If touched with bear hands,
seat and grease residues come into contact with the product that cannot be completely
removed by wipe-cleaning.
8. Inspect the contents for signs of damage. If there is any sign of damage or missing parts,
contact PI immediately.
9. Keep all packaging materials in case the product needs to be returned.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 13
Page 18
Page 19
5 Installation
5
Installation
5.1 General Notes on Installation
NOTICE
Danger of contamination
Only open the inner bag in a cleanroom environment. Wear cleanroom gloves. After
removing the bag, the product may only be stored in a cleanbox, a cleanroom or in a
sealed vacuum chamber
Touch the product only when wearing cleanroom gloves. If touched with bear hands,
seat and grease residues come into contact with the product that cannot be completely
removed by wipe-cleaning.
NOTICE
Unwanted changes in position with vertical mounting!
If the load exceeds the self-locking of the drive when the positioner is mounted vertically,
unintentional changes in the position of the platform will occur. Unwanted changes in the
position of the platform can damage the drive, the load or the environment.
When a positioner is mounted vertically, make sure that the installed load is lower than
the self-locking of the drive (see specification of the holding force in "Data table"
(p. 37)).
NOTICE
Malfunction due to false mounting screws!
Make sure that the screws are vacuum-compliant (e.g. including vent holes)
NOTICE
Cable break!
A cable break leads to failure of the positioner.
Install the positioner so that the cable is not bent too strongly or crushed.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 15
Page 20
5 Installation
HINWEIS
Heating of the L-509 during operation!
The heat produced during operation of the L-509 can affect your application.
Due to lack of surrounding air, heat dissipation from the motor is reduced significantly in a
vacuum.
Install the L-509 so that the application is not impaired by the dissipated heat.
Avoid exceeding the allowed max. velocity of 5 mm/s. Operation within the allowed
velocity range is automatically ensured by correct selection/detection of the product
model in the motion control software.
INFORMATION
For optimal repeatability, all components must be connected firmly together.
INFORMATION
The use of locating pins during mounting reduces deviations from the ideal alignment of the
positioner.
If possible, simulate the positioner motion with a mounted load or make suitable
calculations to detect collisions or unfavorable center of gravity constellations.
If necessary, take suitable constructive measures to avoid collisions and instability in
the overall system.
Avoid or mark danger zones that result from the installation of the positioner and the
application, in accordance with the legal regulations.
16 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 21
5 Installation
5.2 Attaching the L-509 to a Surface
NOTICE
Protruding screw heads!
Protruding screw heads can damage the L-509.
Make sure that the screws are completely fastened and that the screw heads do not
protrude from the countersunk holes so that they do not interfere with the positioner
motion.
NOTICE
Warping of the L-509 due to mounting on uneven surfaces!
Mounting the L-509 on an uneven surface can warp the L-509. Warping reduces the accuracy.
Mount the L-509 onto an even surface. The recommended flatness of the surface is ≤10
µm.
For applications with large temperature changes:
Only mount the L-509 on surfaces that have the same or similar thermal expansion
properties as the L-509.
INFORMATION
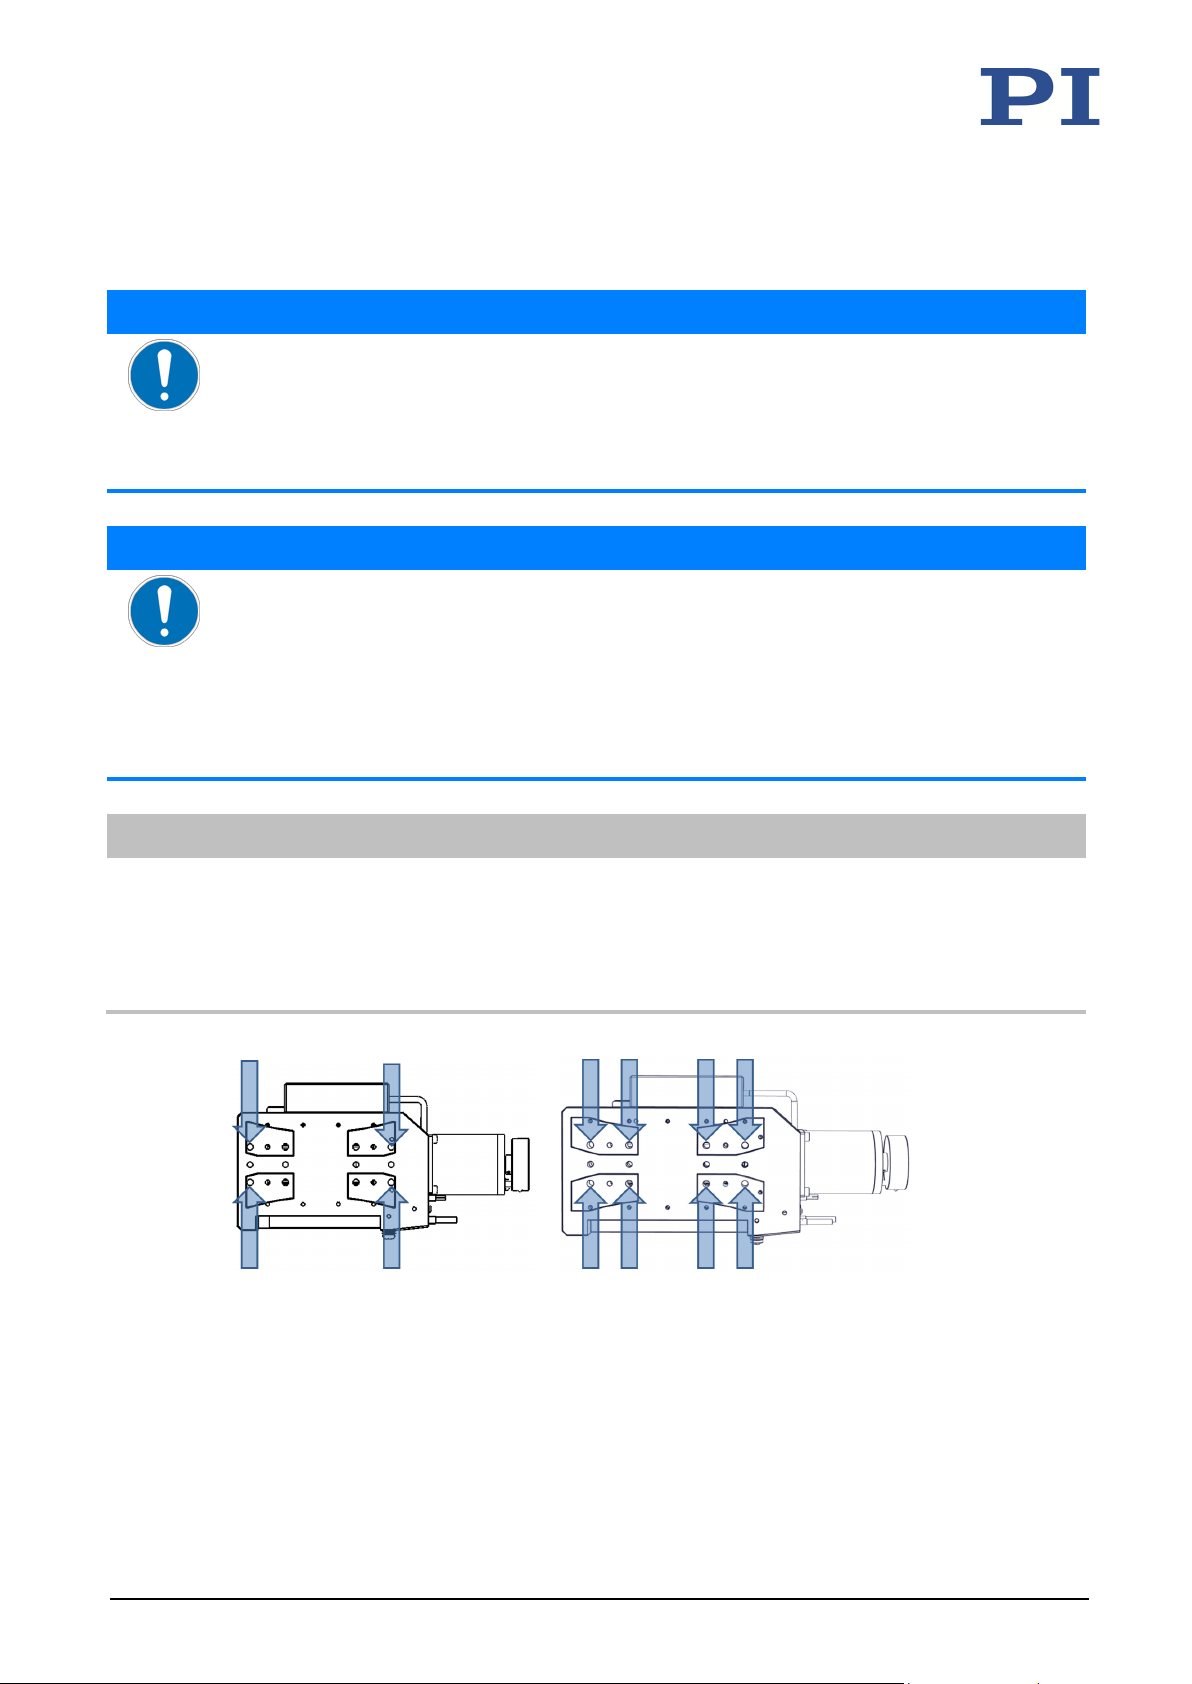
For mounting onto a surface, the L-509 has mounting holes for M4 screws in its base body. The
number of holes available depends on the model:
L-509.02xxxxxx: 4 mounting holes
L-509.03xxxxxx, L-509.05xxxxxx: 8 mounting holes
The correct number of screws and washers is included in the scope of delivery of the L-509.
Figure 4: Position of the holes for mounting the positioner
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 17
Page 22
5 Installation
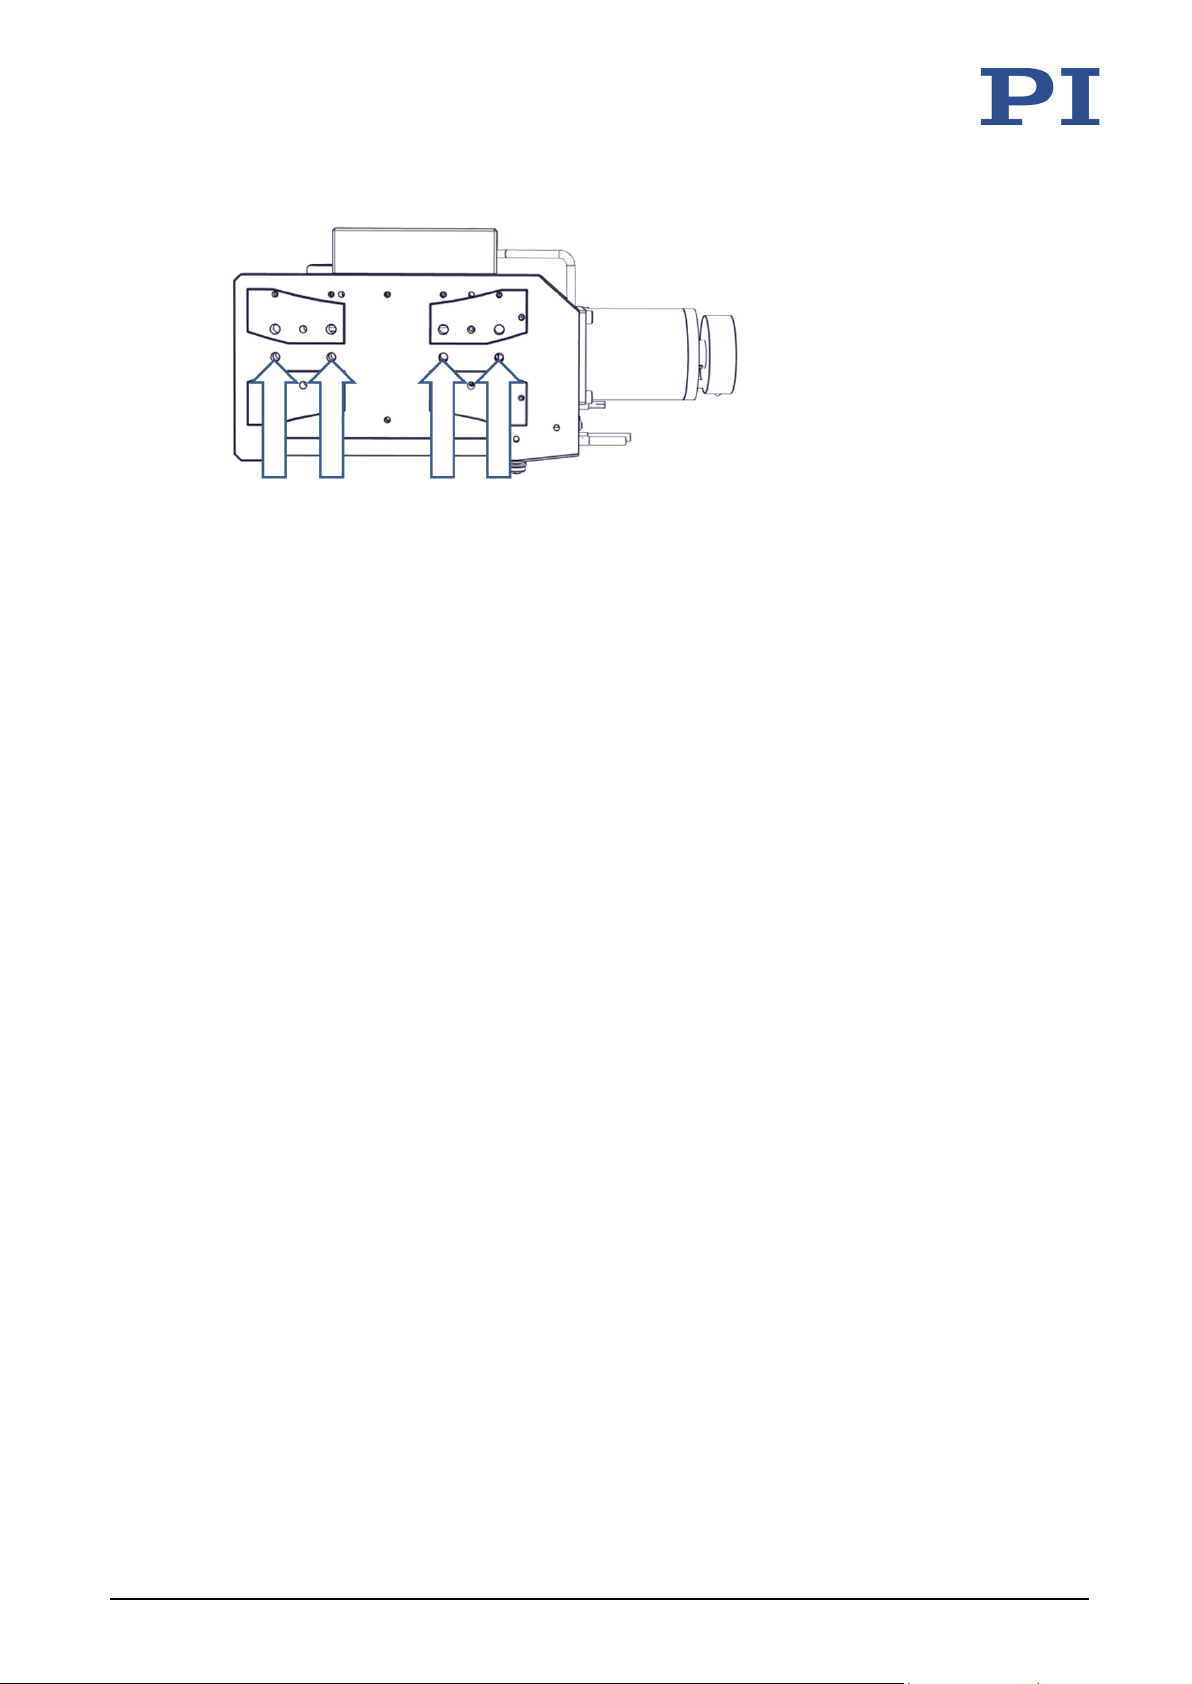
Figure 5: Position of the locating holes for aligning the positioner
Requirements
You have read and understood the general notes on installation (p. 15).
You have provided a suitable surface (for the required position and depth of the holes
for accommodating the screws and locating pins, see "Dimensions" (p. 39)):
− Four or eight M4 threaded holes are present.
− If you use locating pins to align the positioner: Two 4 mm Ø locating holes are
present.
− The flatness of the surface is ≤10 µm.
− For applications with large temperature changes: The surface should have the same
or similar thermal expansion properties as the L-509 (e.g., surface made of
aluminum).
You have accounted for the space required to route cables without bending and
according to regulations.
There is a suitable vacuum feedthrough (see p.11) for the cable connections.
Tools and accessories
Mounting accessories; in the scope of delivery (p. 11)
− 4 or 8 socket head screws, ISO 4762 M4x14
− 2 dowel pins, ISO 2338 - 4 m6 × 12, for use as locating pins
Hex key, AF 3
Mounting the positioner onto a surface
1. Align the positioner on the surface so that the corresponding mounting holes in the
positioner and the surface overlap.
18 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
If you use locating pins to align the positioner:
a) Insert the locating pins into the respective holes in the surface.
b) Place the positioner on the surface so that the locating pins are inserted into the
corresponding locating holes on the other side.
Page 23
5 Installation
2. Allow access to the mounting holes in the base body of the positioner. Possible
measures:
− Temporary startup of the positioner (S. 25) and commanding the platform to a
suitable position
− Moving the platform manually (p. 33)
3. Insert the screws into all accessible mounting holes and tighten.
4. Repeat steps 2 to 4 for all available concealed mounting holes.
5. Check that the positioner is affixed firmly to the surface.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 19
Page 24
5 Installation
5.3 Connecting the L-509 to the Protective Earth Conductor
INFORMATION
It is only necessary to connect the L-509 to the protective earth conductor when both of the
following conditions are met:
The load on the platform of the L-509 must be connected to the protective earth
conductor, but it is not possible to connect the protective earth conductor directly to the
load.
The load and the platform are connected conductively to each other.
INFORMATION
Observe the applicable standards for connecting the protective earth conductor.
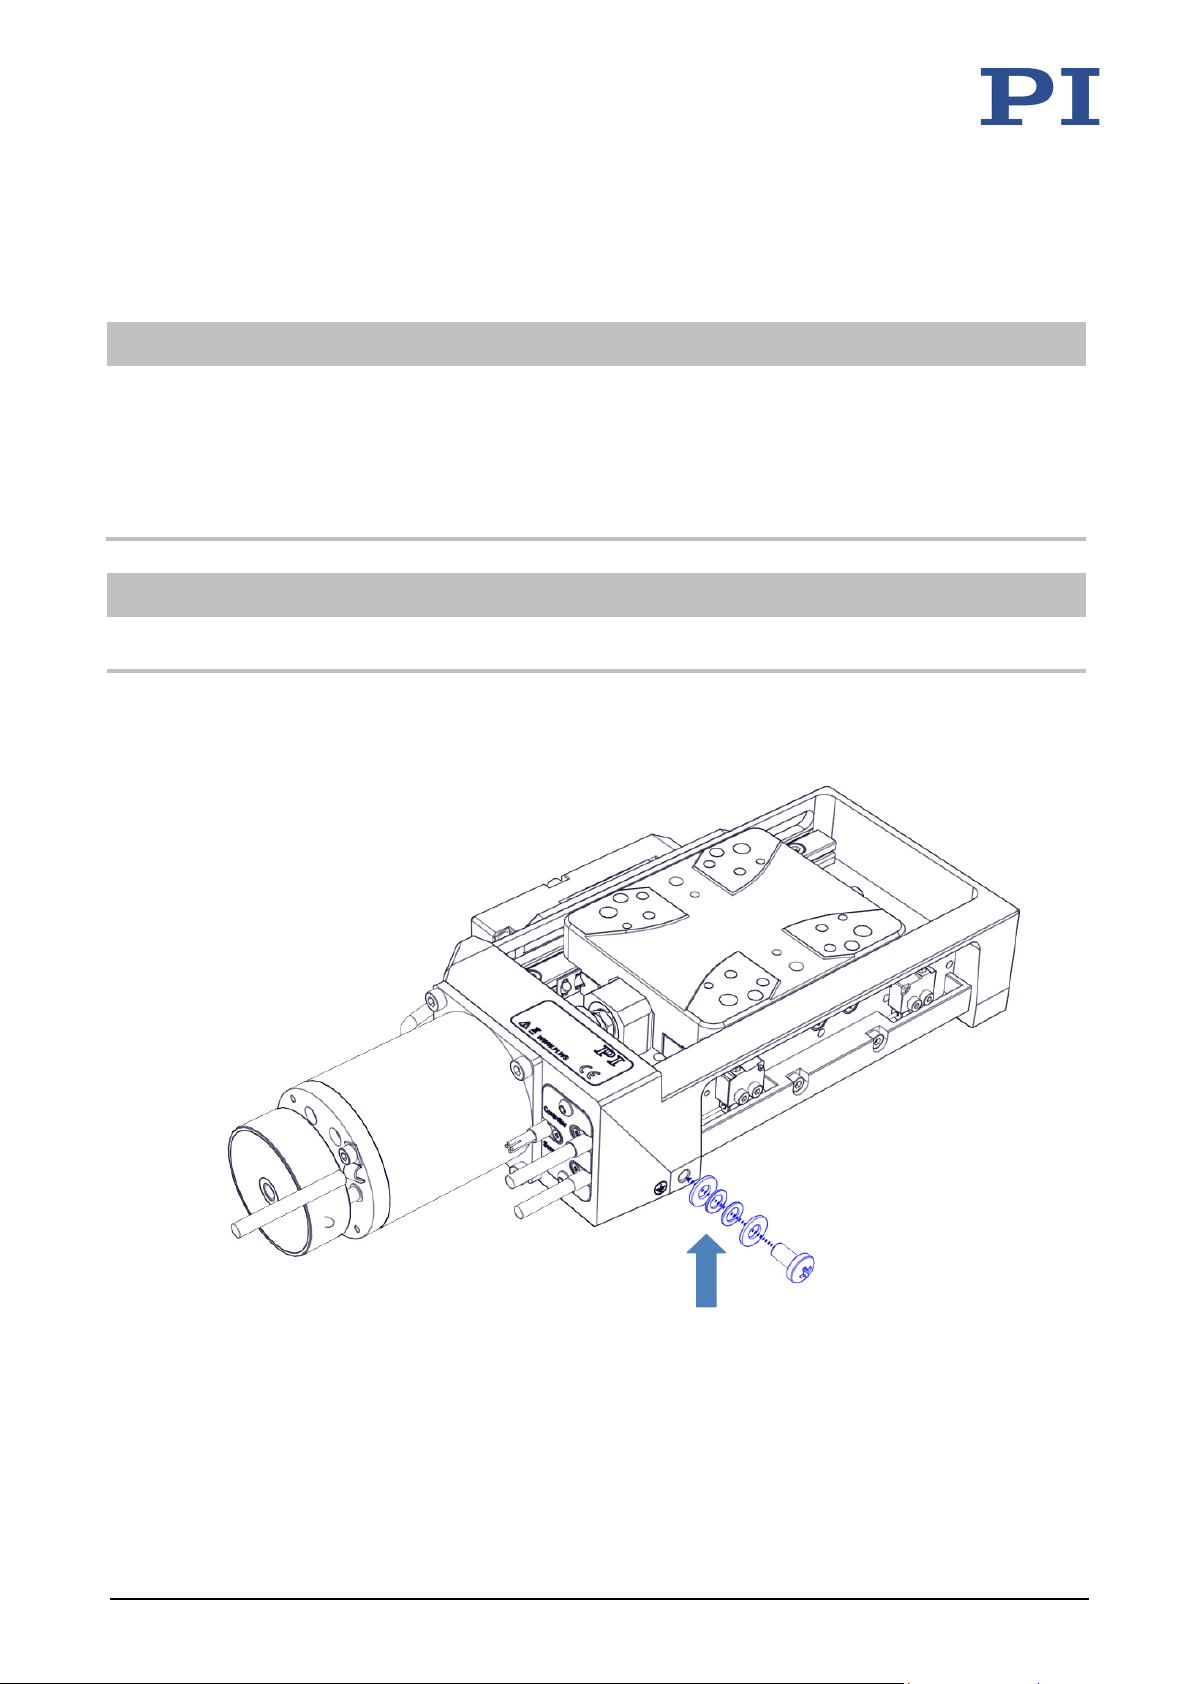
An M4 hole for the protective earth conductor connection is included in one of the longitudinal
sides of the L-509. In the following figure, this hole is marked with an arrow.
20 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Figure 6: Components of the protective earth conductor
Page 25
5 Installation
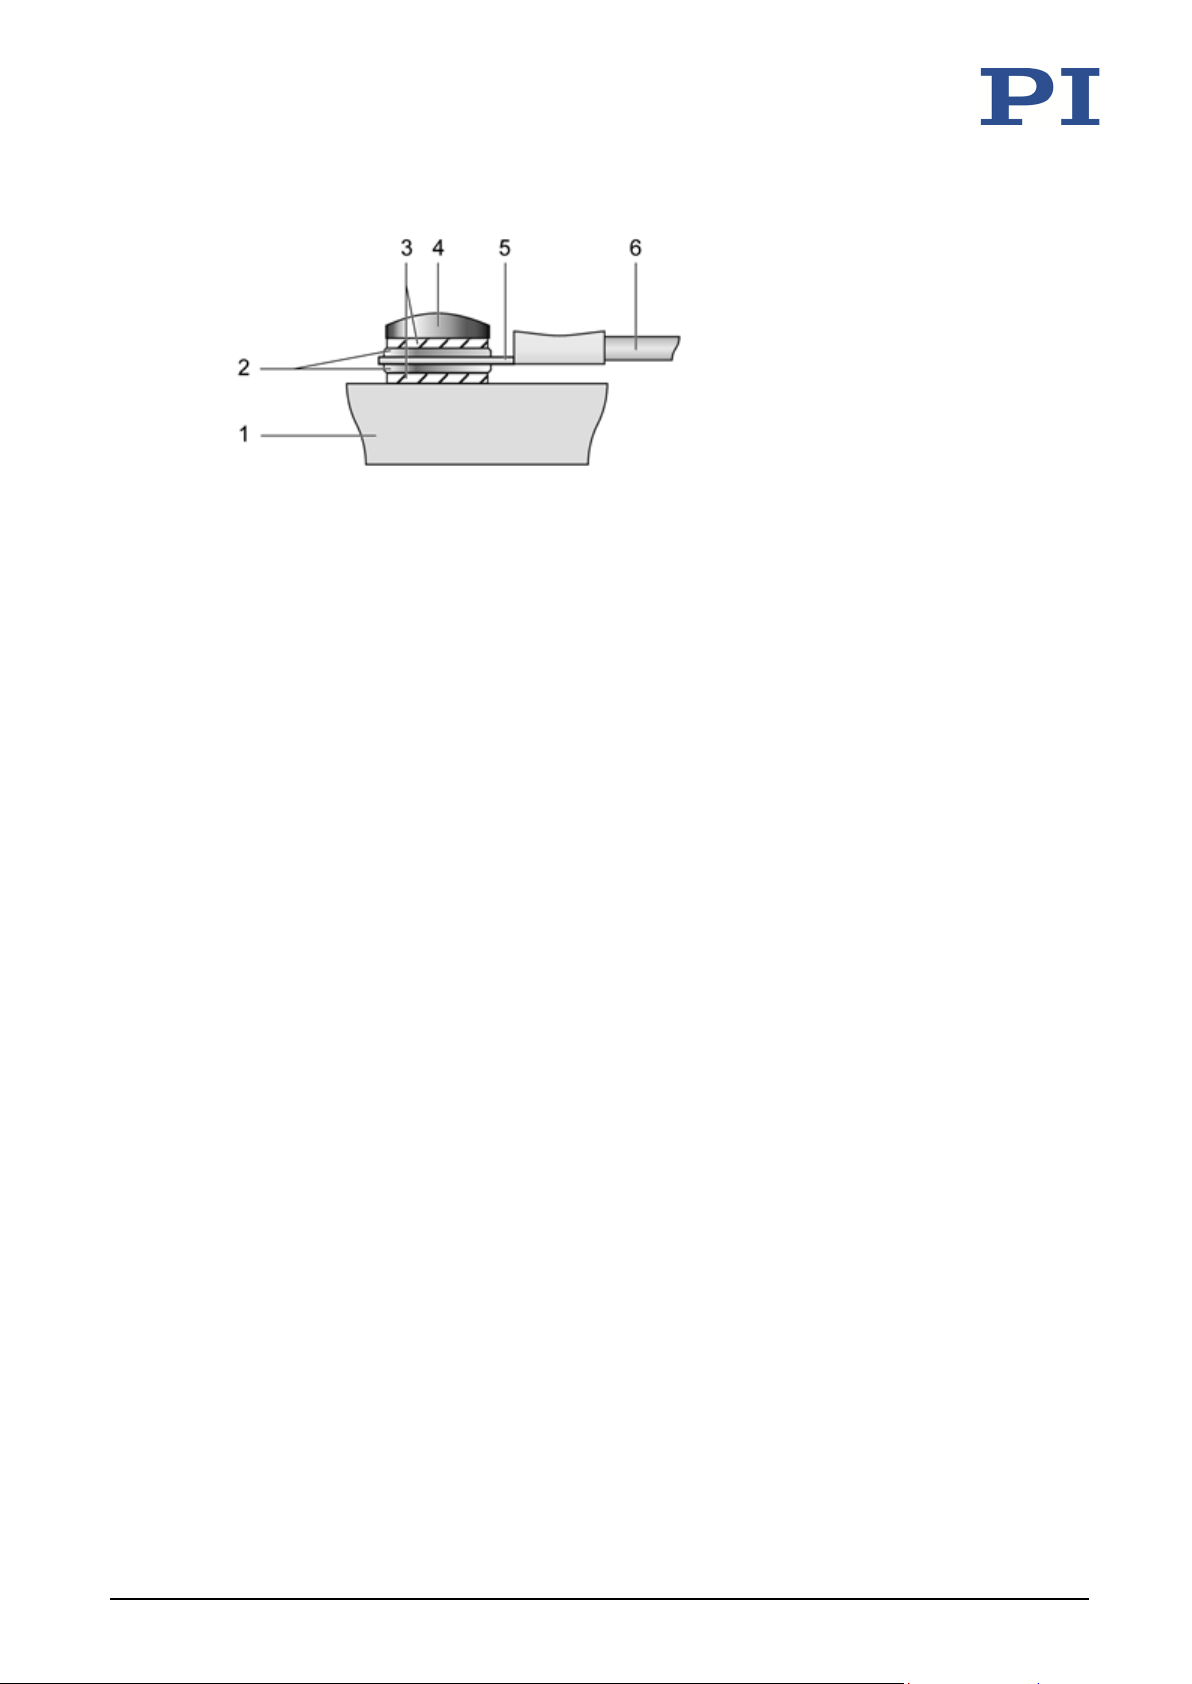
Figure 7: Mounting of the protective earth conductor (profile view)
1 Base body of the L-509
2 Flat washer
3 Safety washer
4 Screw
5 Cable lug
6 Protective earth conductor
Requirements
You have read and understood the general notes on installation (p. 15).
Tools and accessories
Suitable protective earth conductor: Cross-sectional area of the cable ≥ 0.75 mm
Vacuum-compliant screw, M4x8, ISO 7045
2 washers ISO 7089-4
2 safety washers S4
Suitable screwdriver
2
Connecting the L-509 to the Protective Earth Conductor
1. If necessary, attach a suitable cable lug to the protective earth conductor.
2. Affix the cable lug of the protective earth conductor using the M4 screw on the
protective earth connection of the L-509 as shown in the profile view.
3. Tighten the M4 screw with a torque of 1.2 Nm to 1.5 Nm.
4. Make sure that the contact resistance at all connection points relevant for attaching the
protective earth conductor is <0.1 Ω at 25 A.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 21
Page 26
5 Installation
5.4 Affixing the Load to the L-509
NOTICE
Impermissibly high load on the positioner!
An impermissible high load impairs the motion of the platform and can damage the
positioner.
When considering the mass and mounting method of the load, pay attention to the
specified maximum permissible forces that may act on the platform (p. 37).
NOTICE
Excessively long screws!
Screws and locating pins that are inserted too deeply can damage the lower positioner.
Pay attention to the depth of the mounting holes in the platform (p. 39) of the lower
positioner.
Only use screws and locating pins of the correct length for the respective mounting
holes.
Requirements
You have read and understood the general notes on installation (p. 15).
You have mounted the positioner properly onto a surface (p. 17).
The positioner is not connected to the controller.
You have prepared the load so that it can be affixed to the mounting holes on the
platform (p. 40):
− The distance between the center of gravity of the load and the center of the
platform is as small as possible in all directions.
− At least two points are provided for mounting the load on the platform (ideally:
three or four mounting points).
− If you use locating pins for aligning the load: You have made two locating holes of
Ø 4 mm H7 in the load for accommodating locating pins.
22 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 27
5 Installation
Tools and accessories
At least 2 vacuum-compliant screws of suitable length. Options:
− M4 screws
− M6 screws
Suitable tool for tightening the screws
Optional: 2 dowel pins, ISO 2338 - 4 m6 of suitable length for aligning the load on the L-
509.
Affixing the load
1. Align the load so that the selected mounting holes in the platform (p. 40) can be used to
affix it.
If you use locating pins to align the load:
c) Insert the locating pins into the locating holes in the platform.
d) Place the load on the platform so that the locating pins are inserted into the
corresponding locating holes on the other side.
2. Use the screws to affix the load on the selected mounting holes in the platform.
3. Check that the load is affixed firmly to the platform of the positioner.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 23
Page 28
5 Installation
5.5 Connecting the L-509 to a Controller
NOTICE
Damage if an incorrect controller or motor cable is connected!
Connecting a positioner to an unsuitable controller or using an unsuitable motor
cable can cause damage to the positioner or controller.
Only connect the positioner to a suitable controller (p. 12).
To connect the positioner to the controller, only use a motor cable that is
suitable for the controller. Suitable cables for the vacuum and atmospheric side
are supplied as follows:
− C-663.11 controller: C-815.38 motor cable
− C-663.12 controller: C-815.00SA0338-0300 motor cable.
− SMC Hydra controller: 720090620-0300 motor cable
Requirements
You have read and understood the general notes on installation (p. 15).
You have installed the controller.
You have read and understood the user manual of the controller.
The controller is switched off.
Tools and accessories
Cable from the scope of delivery of the positioner (p. 11)
Vacuum feedthrough incl. according connectors
Suitable tools for tightening the screws to the connections
Connecting the L-509 to a Controller
1. Remove the ESD protection from all connections of the L-509.
2. Connect the cable(s) of the vacuum side to the corresponding connector(s) of vacuum
feedthrough.
3. Connect the cable(s) of the air side to the corresponding connector(s) of vacuum
feedthrough.
4. Use the integrated screws (if applicable) to secure the connections against accidental
disconnection.
24 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 29
6 Startup
6
Startup
6.1 General Notes on Start-Up
CAUTION
Risk of crushing by moving parts!
There is a risk of minor injury from crushing between the moving parts of the positioner or
the load and a fixed part or obstacle.
Use protective structures to keep limbs away from areas in which they could be caught
by moving parts.
Observe the safety distances in accordance with DIN EN ISO 13857 when installing
protective structures.
NOTICE
Contamination of the positioner!
Contamination, in particular due to sweat or grease on the skin, cannot normally be
completely cleaned by wiping.
Wear cleanroom gloves always when handling the positioner.
Make sure that the positioner does not come into contact with contaminated surfaces or
tools.
Make sure that the positioner is stored in a cleanbox, cleanroom or in a sealed vacuum
chamber.
HINWEIS
Heating of the L-509 during operation!
The heat produced during operation of the L-509 can affect your application.
Due to lack of surrounding air, heat dissipation from the motor is reduced significantly in a
vacuum.
Install the L-509 so that the application is not impaired by the dissipated heat.
Avoid exceeding the allowed max. velocity of 5 mm/s. Operation within the allowed
velocity range is automatically ensured by correct selection/detection of the product
model in the motion control software.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 25
Page 30
6 Startup
NOTICE
Damage from collisions!
Collisions can damage the positioner, the load to be moved, and the surroundings.
Make sure that no collisions are possible between the positioner, the load to be moved,
and the surroundings in the motion range of the positioner.
Do not place any objects in areas where they can be caught by moving parts.
Stop the motion immediately if a controller malfunction occurs.
If possible, adapt the travel range limits of your mechanical system in the software that
you use for commanding the motion.
NOTICE
Damage if an incorrect controller or motor cable is connected!
Connecting a positioner to an unsuitable controller or using an unsuitable motor
cable can cause damage to the positioner or controller.
Only connect the positioner to a suitable controller (p. 12).
To connect the positioner to the controller, only use a motor cable that is
suitable for the controller. Suitable cables for the vacuum and atmospheric side
are supplied as follows:
− C-663.11 controller: C-815.38 motor cable
− C-663.12 controller: C-815.00SA0338-0300 motor cable.
− SMC Hydra controller: 720090620-0300 motor cable
NOTICE
Operating voltage excessively high or incorrectly connected!
Operating voltages that are excessively high or incorrectly connected can cause damage to
the L-509.
Do not exceed the operating voltage range (p. 38) that is specified for the L-509.
Operate the L-509 only when the operating voltage is properly connected; see "Pin
Assignment" (p. 43).
NOTICE
Damage or considerable wear due to high accelerations!
High accelerations can cause damage to or considerable wear on the mechanics.
Stop the motion immediately if a controller malfunction occurs.
Ensure that the end of the travel range is approached at low velocity.
Determine the maximum velocity for your application.
26 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 31
6 Startup
NOTICE
Unintentional motion!
Unintentional motion of the L-509 is possible when it is connected to the controller. Defective
software or incorrect operation of the software can also result in unintentional motion.
Do not place any objects in areas where they can be caught by moving parts.
Before connecting the L-509, check whether a macro is defined as the startup macro in the
controller, and cancel the selection of the startup macro if necessary.
INFORMATION
Improper setting of the servo-control parameters can impair the performance of the L-509.
This can have the following consequences:
Oscillation
Imprecise approach of the position
Settling time is too long
If the performance of the L-509 is not satisfactory, check the settings for the servo-control
parameters of your controller.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 27
Page 32
6 Startup
6.2 Starting up the Positioner
Requirements
You have read and understood the general notes on startup (p. 25).
For starting up with a load or in a multi-axis system: You have properly installed the
positioner (p. 24).
You have read and understood the user manual of the controller used.
You have read and understood the manual of the PC software used.
The controller and the required PC software have been installed. All connections on the
controller have been set up (see "Connecting the L-509 to the Controller" (p. 24) and
the user manual of the controller).
Starting up the positioner
1. Start up the controller (see user manual of the controller).
Configure the controller during startup using the PC software for the positioner used
(see user manual of the controller, and the PC software):
− If you use a controller from PI: Select the entry in the positioner database that
exactly fits the positioner model used (p. 28).
− If you use a controller from another manufacturer: Enter the parameters into the
corresponding PC software that exactly fit the positioner model used; see the
overview of the operating parameters for DC motor controllers or stepper motor
controllers.
2. Before sealing the vacuum chamber, start a few motion cycles for testing purposes (see
user manual of the controller).
6.2.1 L-509 Entries in the Positioner Database of PI
For PI controllers, you can select the connected positioner from a positioner database in the
corresponding PC software. The appropriate operating parameters are thus loaded to the
controller. You can find a detailed description in the user manual for the controller or in the
manual for the PC software used.
28 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 33
7 Maintenance
7
Maintenance
7.1 General Notes on Maintenance
NOTICE
Contamination of the positioner!
Contamination, in particular due to sweat or grease on the skin, cannot normally be
completely cleaned by wiping.
Wear cleanroom gloves always when handling the positioner.
Make sure that the positioner does not come into contact with contaminated surfaces or
tools.
Make sure that the positioner is stored packed in a cleanbox, cleanroom or in a sealed
vacuum chamber.
NOTICE
Damage due to improper maintenance!
Improper maintenance can result in misalignment and failure of the L-509.
Only loosen screws according to the instructions in this manual.
7.2 Performing a Maintenance Run
Depending on the operating conditions and the period of use of the L-509, the following
maintenance measures are required:
Maintenance run
The maintenance run serves to distribute the existing lubricant.
After 500 operating hours or at least after 1 year, perform a maintenance run over the
entire travel range, in order for the existing lubricant to be distributed evenly.
If you operate your positioner continuously over only a short travel range (<20%of the
entire travel range), perform a run across the entire travel range approximately every
2000 motion cycles.
Lubrication
Under laboratory conditions, the positioner needs extra lubrication in exceptional cases only.
For continuous industrial use, the lubrication intervals must be defined individually.
Do not relubricate the L-509 without consulting our customer service department.
(p. 35).
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 29
Page 34
7 Maintenance
7.3 Cleaning the L-509
Requirements
You have disconnected the positioner from the controller and the power supply.
Cleaning the positioner
If necessary, clean the surface of the positioner with a lint-free cleanroom cloth that
has been dampened with clean isopropyl alcohol (99.9% or better).
30 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 35
8 Troubleshooting
Reduce the load. Make sure that the self-locking
8
Troubleshooting
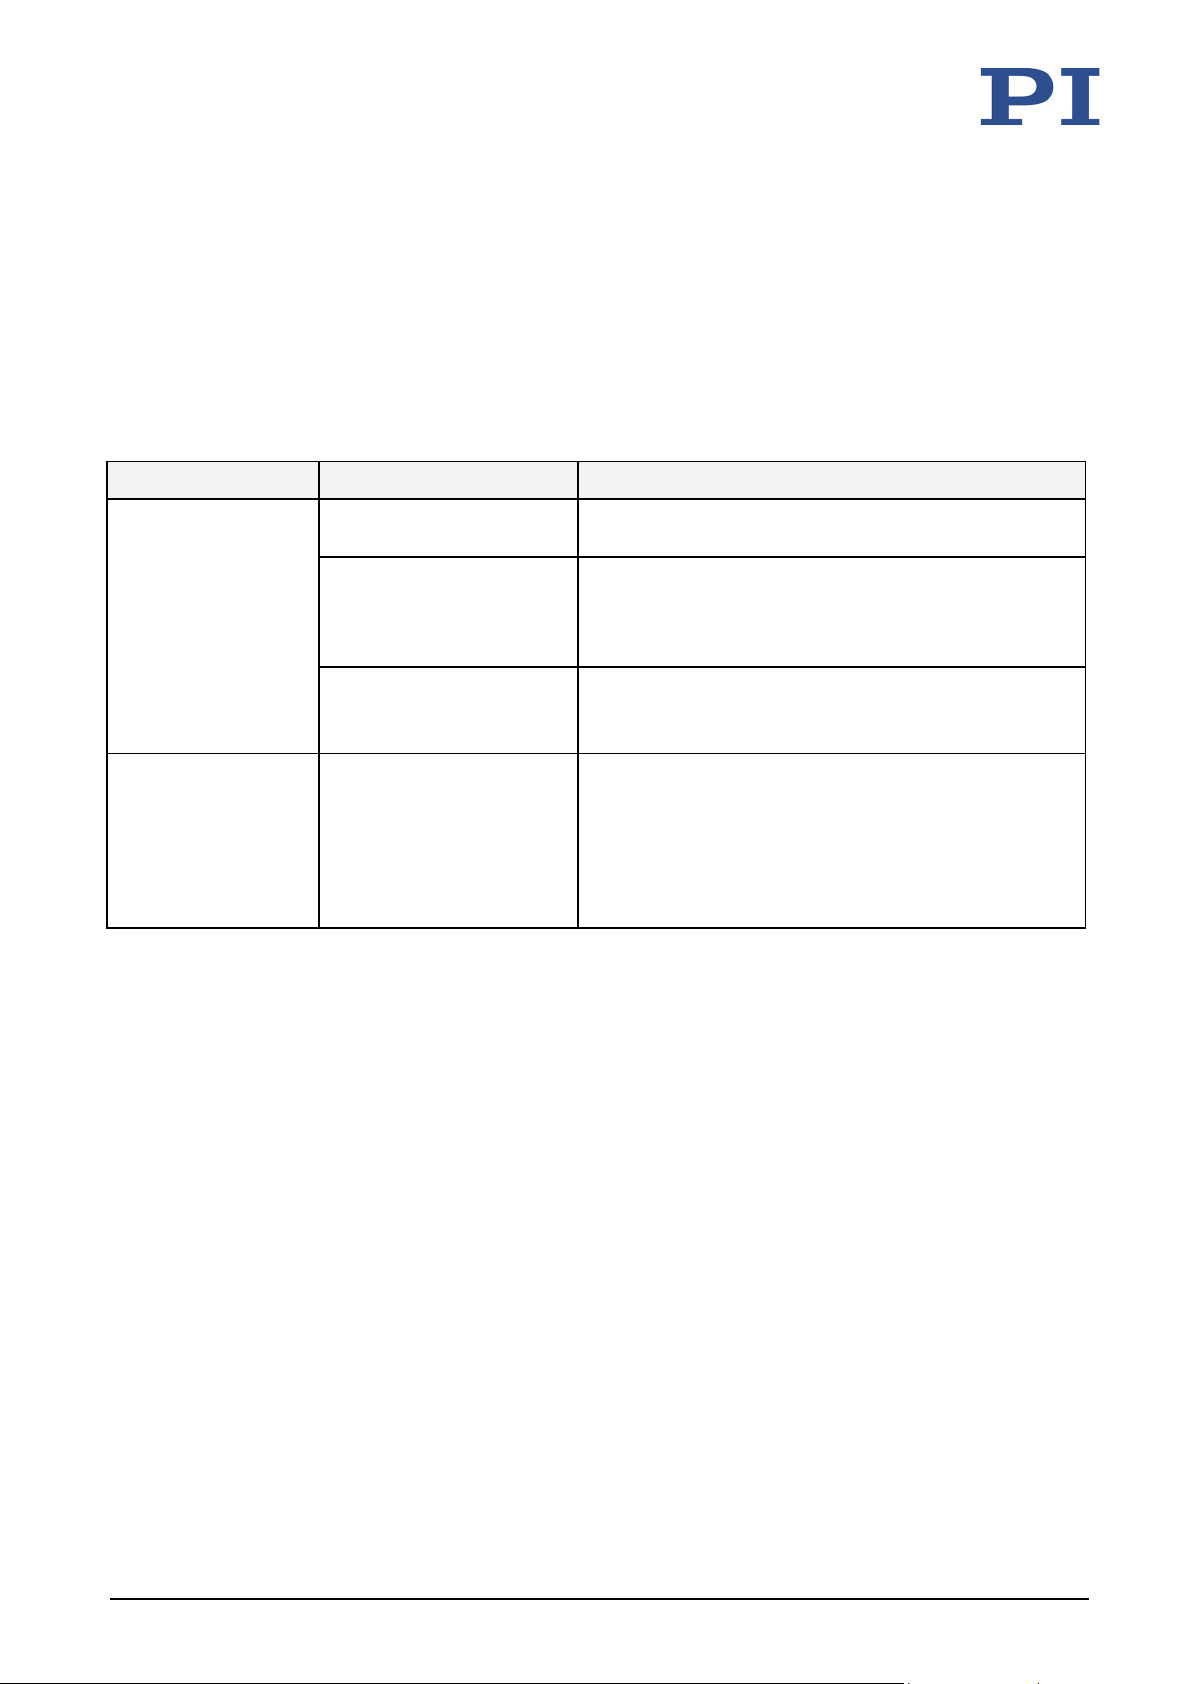
8.1 Possible Causes and Remedies
Problem Possible causes Solution
Reduced positioning
accuracy
Functional
impairment after
system modification
Warped base body
When the L-509 is
mounted vertically: The
load exceeds the selflocking of the drive.
Increased wear due to
small motion over a long
period of time
Controller was
replaced.
The LS509 was
replaced by another
model.
Mount the L-509 onto an even surface. The
recommended flatness of the surface is ≤ 10 µm.
(see specification of the holding force in the data
table) of the drive is not exceeded (p.
Perform a maintenance run over the entire travel
range (p.
Controller from PI:
Load the parameters from the positioner database
that correspond to the combination of controller
and the L-509 model.
Controller from a third-party supplier:
Check the operating parameters.
29).
37)).
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 31
Page 36
8 Troubleshooting
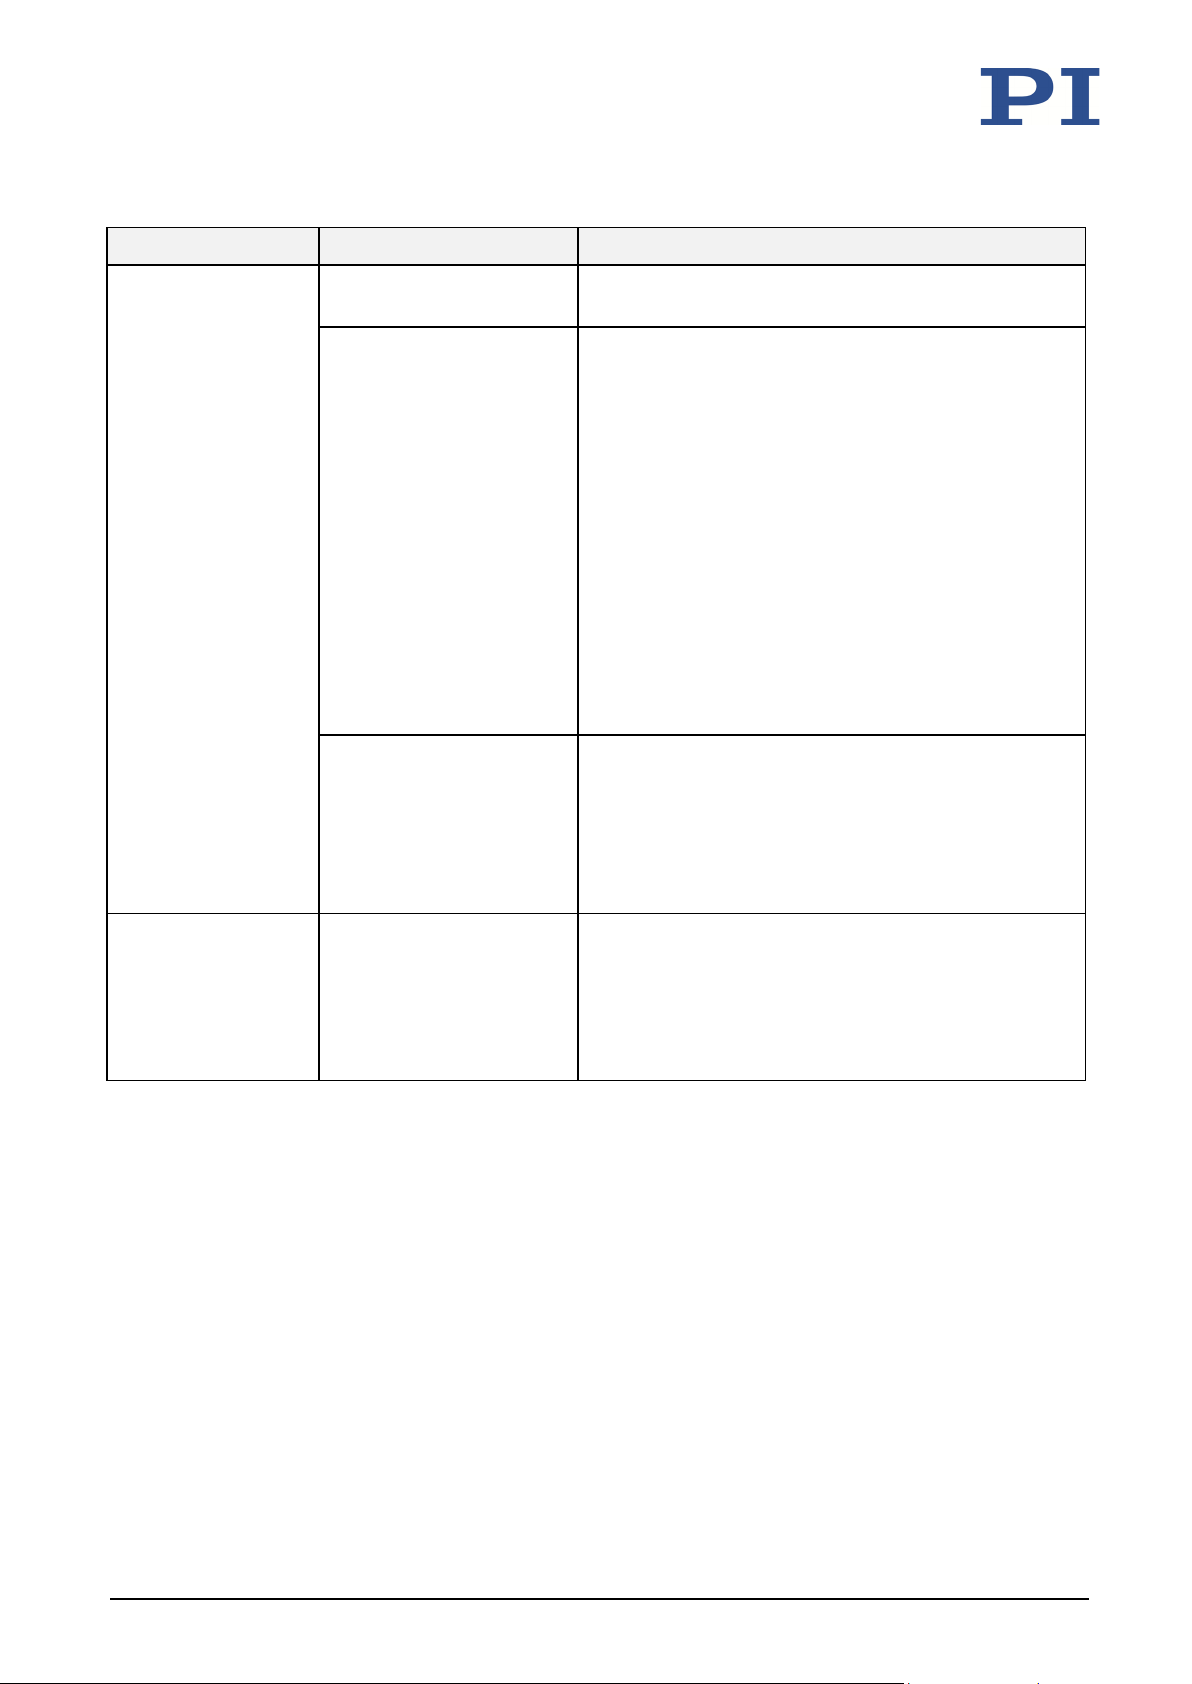
Check all connecting cables.
The motor is overloaded by
Problem Possible causes Solution
Mechanical system
does not move; no
operating noise can
be heard.
Controller not correctly
connected or defective.
When a PI controller is
used: Axis motion error.
Platform has triggered the
limit switch.
Check the controller.
Motion error = The difference between the current
position and the commanded position exceeds the
specified maximum value in closed-loop operation. For
example, motion errors can be caused by malfunctions
of the drive or the position sensor of the positioner.
1. Read out the error code of the controller in the PC
software. If there is a motion error, error code 1024 is output.
2. Check your system and make sure that all axes can
be moved safely.
3. Switch on the servo mode for the affected axis in
the PC Software.
For details, see the user manual of the controller.
If you use a controller from PI:
1. Switch on the servo mode for the affected axis
again in the PC software.
2. Command an axis motion away from the limit
switch in the PC software.
Actual position
deviates from the
displayed position.
If the problem that occurred with your system is not listed in the table above or cannot be
solved as described, contact our customer service department (p. 35).
an external load torque or
the mass to be driven in
the case of strong
acceleration or
deceleration.
The motor skips steps. The information on the current
position is lost without the controller detecting the
state.
Determine the maximum velocity for a positioner
with a stepper motor in the application.
Start a new move.
32 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 37
8 Troubleshooting
8.2 Moving the Platform Manually
NOTICE
Risk of contamination
Contamination due to improper handling of the positioner can impair the quality of the
vacuum.
Do not touch the positioner with bare hands.
When handling, use suitable cleanroom gloves.
INFORMATION
It can be necessary to move the platform manually to provide access to mounting holes for
mounting screws in the base body of the positioner.
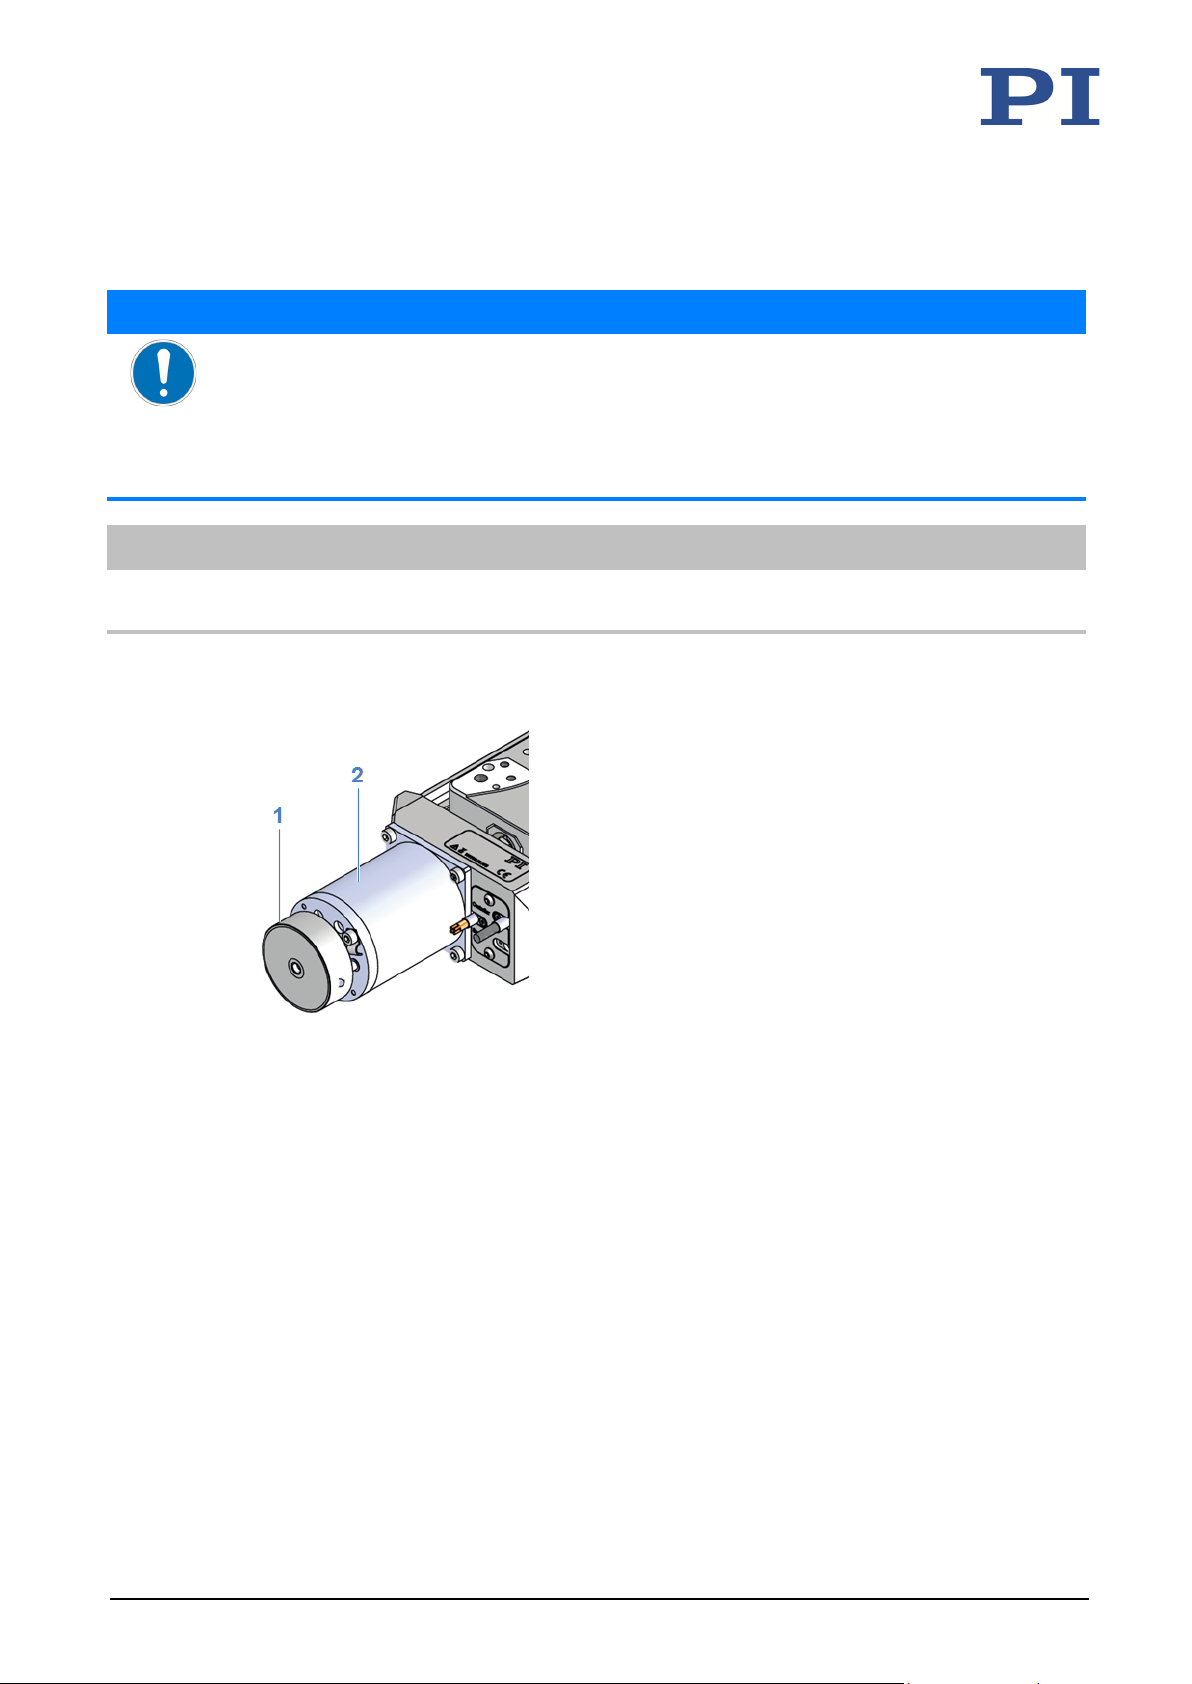
Figure 8: Position of the vibration absorber
1 Vibration absorber
2 Motor
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 33
Requirements
The positioner is not connected to the controller.
Moving the platform manually (use cleanroom gloves!)
Turn the vibration absorber as far as necessary:
− Rotating the absorber clockwise: Platform moves towards the motor
− Rotating the absorber counterclockwise: Platform moves away from the motor
The rotary motion is transferred directly to the drive screw.
Page 38
Page 39
9 Customer Service Department
9
Customer Service Department
For inquiries and orders, contact your PI sales engineer or send us an email (mailto:
[email protected]).
If you have questions concerning your system, have the following information ready:
− Product codes and serial numbers of all products in the system
− Firmware version of the controller (if present)
− Version of the driver or the software (if present)
− Operating system on the PC (if present)
If possible: Take photographs or make videos of your system that can be sent to our
customer service department if requested.
The latest versions of the user manuals are available on our website (p. 3) for download.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 35
Page 40
Page 41
10 Technical Data
10
Technical Data
10.1 Specifications
10.1.1 Data Table
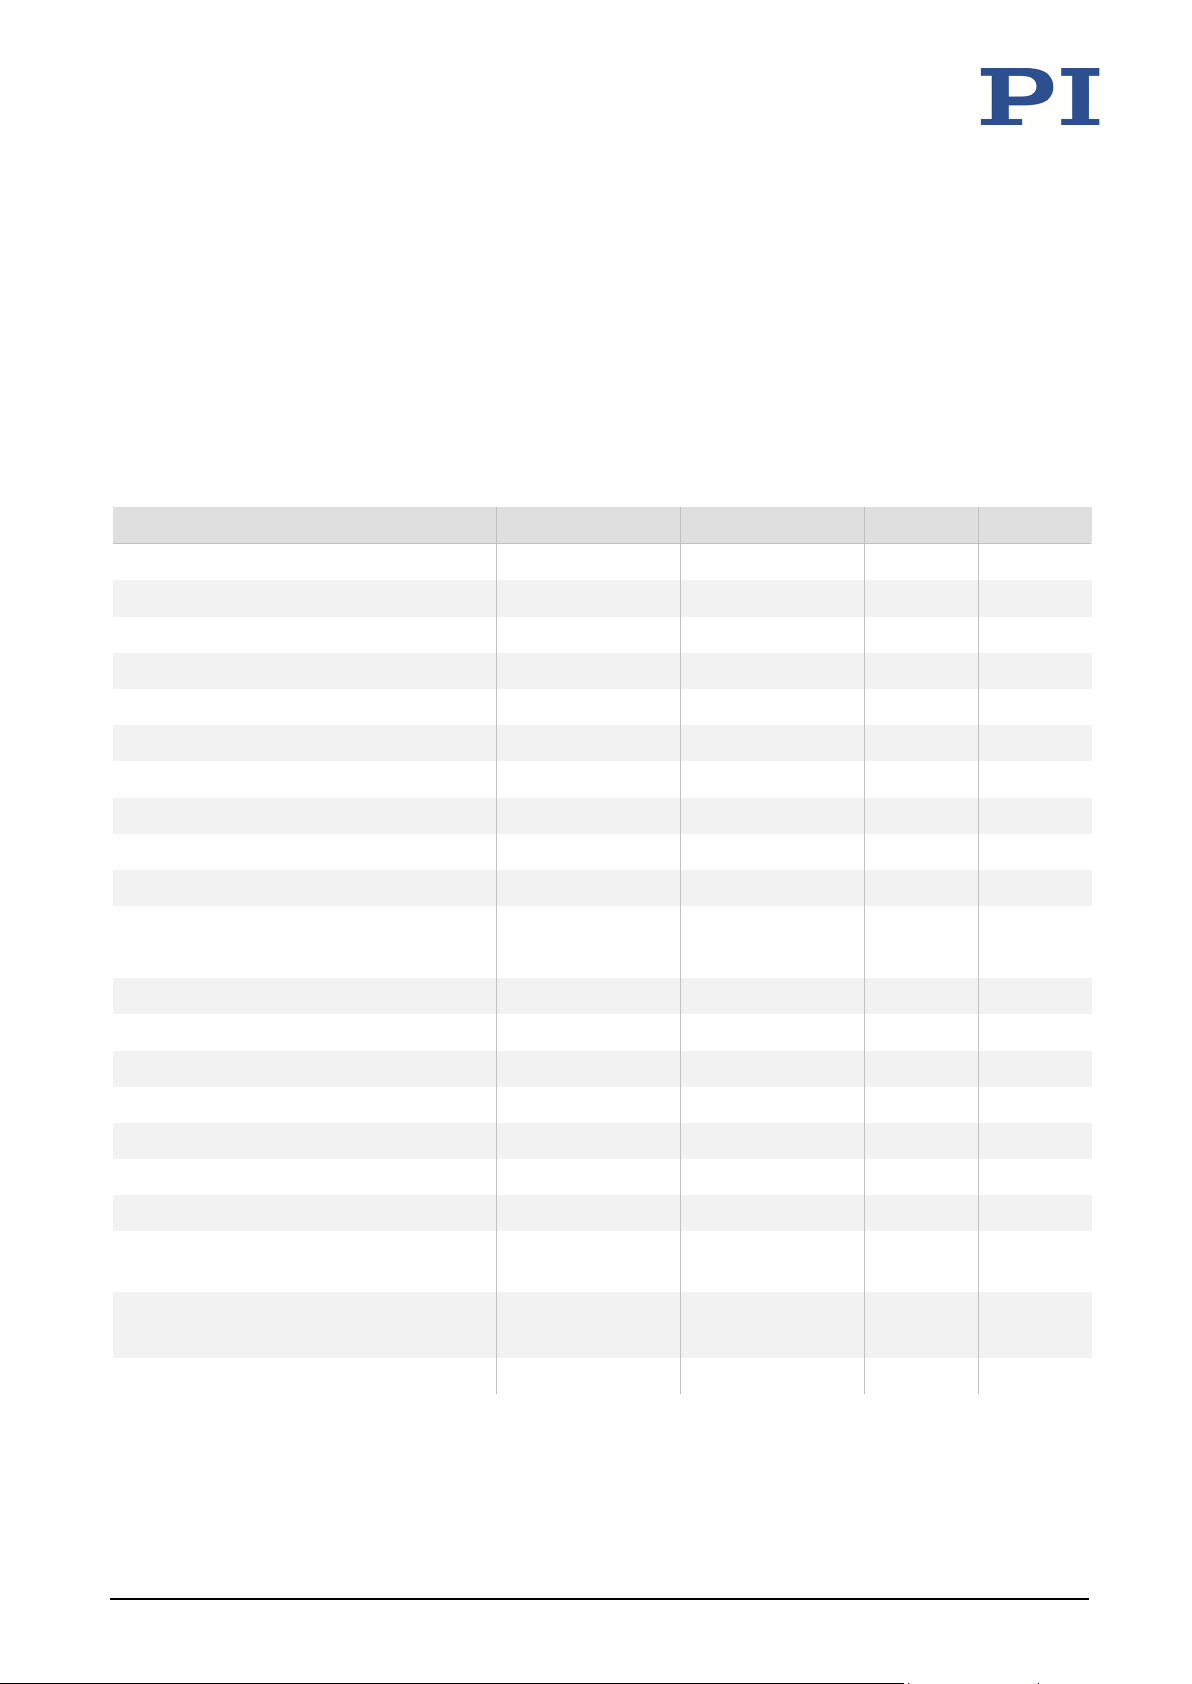
L-509.0x1311V7 L-509.0x1300V7 Unit Tolerance
Motion and positioning
Travel range* 26 / 52 / 102 26 / 52 / 102 mm max.
Integrated sensor Linear encoder –
Design resolution 0.001** 0.315*** µm typ.
Minimum incremental motion 0.01 0.315*** µm typ.
Unidirectional repeatability - 0.3 µm typ.
Backlash 0.5 µm typ.
Bidirectional repeatability ±0.2 µm
Crosstalk, angular error xry (pitch) ±60 / ±90 / ±120 ±60 / ±90 / ±120 µrad typ.
Crosstalk, angular error xrz (yaw) ±60 / ±90 / ±120 ±60 / ±90 / ±120 µrad typ.
Velocity, short-term 10 10 mm/s max.
Velocity, long-term 5 5 mm/s max.
Mechanical properties
Drive screw pitch 1 1 mm
Load capacity 100 100 N max.
Push/pull force 60 60 N max.
Permissible lateral force 50 50 N max.
Holding force 60 60 N max.
Drive properties
Motor Type 2-phase stepper
motor
2-phase stepper
motor
Operating voltage 24
Limit switches Mechanical Mechanical
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 37
48
24
48
V
V
nom.
max.
Page 42
10 Technical Data
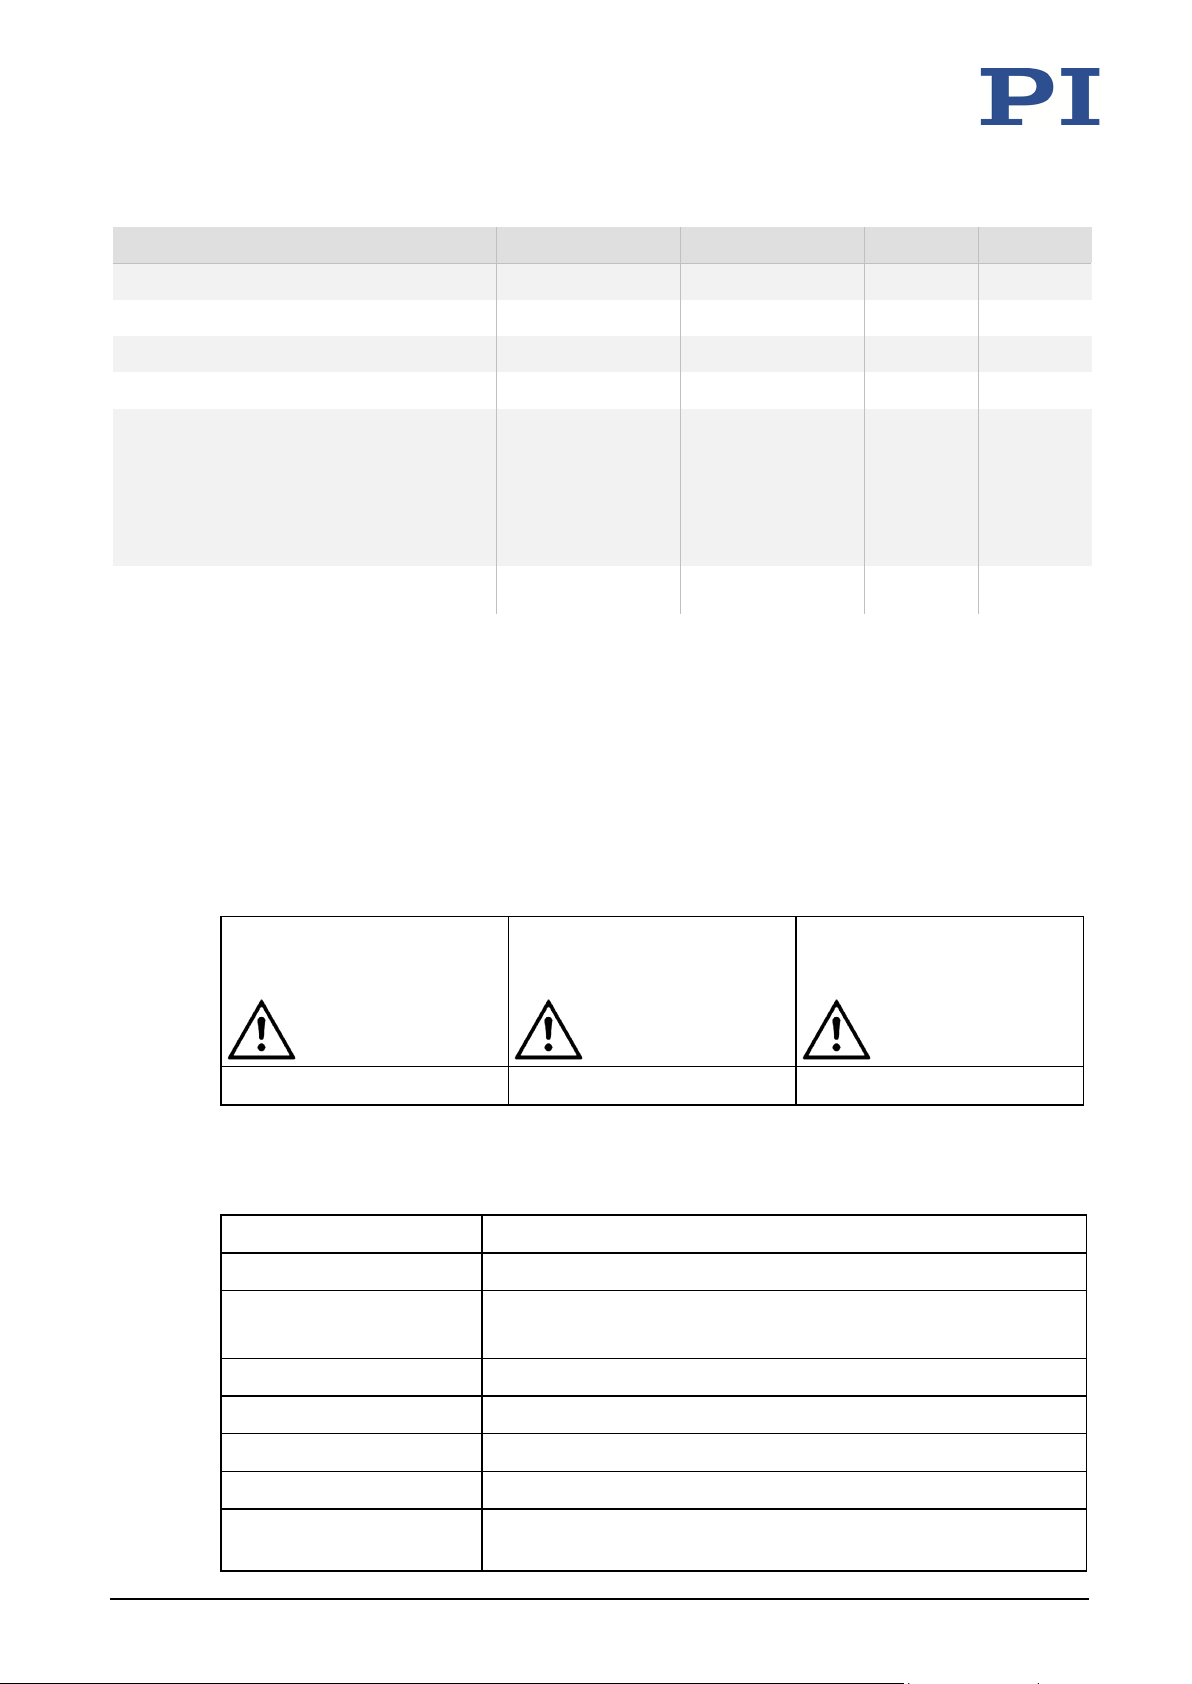
SMC Hydra
(double axis)
C-663 (single axis)
L-509.0x1311V7 L-509.0x1300V7 Unit Tolerance
Miscellaneous
Operating temperature range 0 to 55 -20 to 65 °C
Material Aluminum, steel Aluminum, steel
Mass 1.4 / 1.6 / 1.9 1.4 / 1.6 / 1.9 kg
Connector Vacuum-compliant
connectors D-Sub
15 (motor), D-Sub
9 (linear encoder),
Vacuum-compliant
connector D-Sub
15 and air side
cable (3 m)
and air side cables
(3 m)
Recommended controllers/drivers
* Travel range of the variants: L 509.02xxxxV7: 26 mm (1"), L 509.03xxxxV7: 52 mm (2"),
L-509.05xxxxV7: 102 mm (4").
**(Analog) sin/cos signals with U
= 1 V, operation with SMC Hydra controller with maximum
pp
interpolation.
*** 200 full steps/rev., max. 1.2 A/phase. Motor resolution with C-663 stepper motor
controller.
10.1.2 Maximum Ratings
The positioners are designed for the following operating data:
Maximum operating voltage Operating frequency Maximum power
48 V 0 Hz 10 W
10.1.3 Ambient Conditions and Classifications
The following ambient conditions and classifications must be observed for the L-509:
Area of application For indoor use only
Maximum altitude 2000 m
Relative humidity Max. 80 % for temperatures up to 31 °C
Linearly decreasing to 50 % at 40 °C
Storage temperature -20 °C to 70 °C
Transport temperature -20 °C to 70 °C
Supply fluctuations Max. ±10 % of the nominal voltage
consumption
38 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Degree of pollution 2
Degree of protection
according to IEC 60529
IP00
Page 43
10 Technical Data
10.2 Dimensions
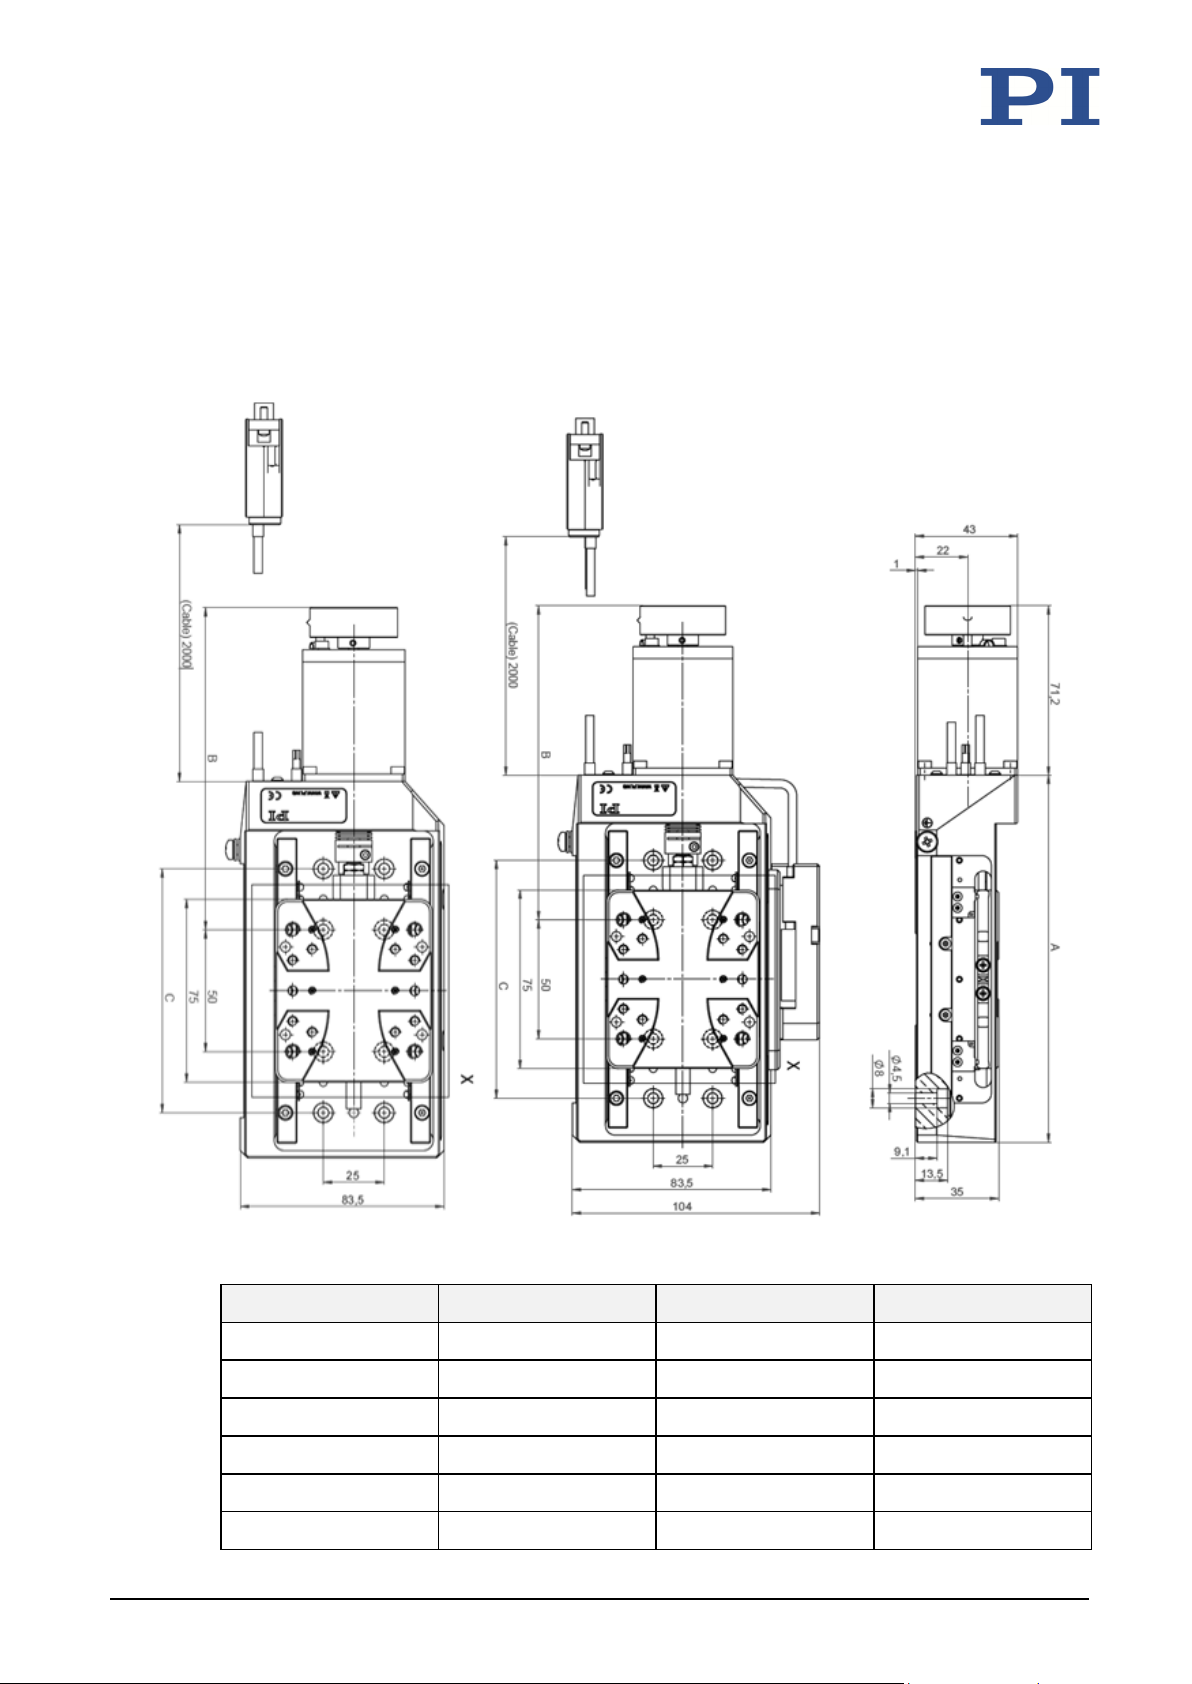
10.2.1 L-509 Positioner
Dimensions in mm. For a detailed view (X) of the platform, see below.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 39
Figure 9: Dimensions for L 509.0x1300V7 (left and right) and L-509.0x1311V7 (middle and right)
Model A B C
L-509.021300V7 135.3 122.5 100
L-509.021311V7 135.3 122.5 100
L-509.031300V7 154.3 132 100
L-509.031311V7 154.3 132 100
L-509.051300V7 204.3 157 150
L-509.051311V7 204.3 157 150
Page 44
10 Technical Data
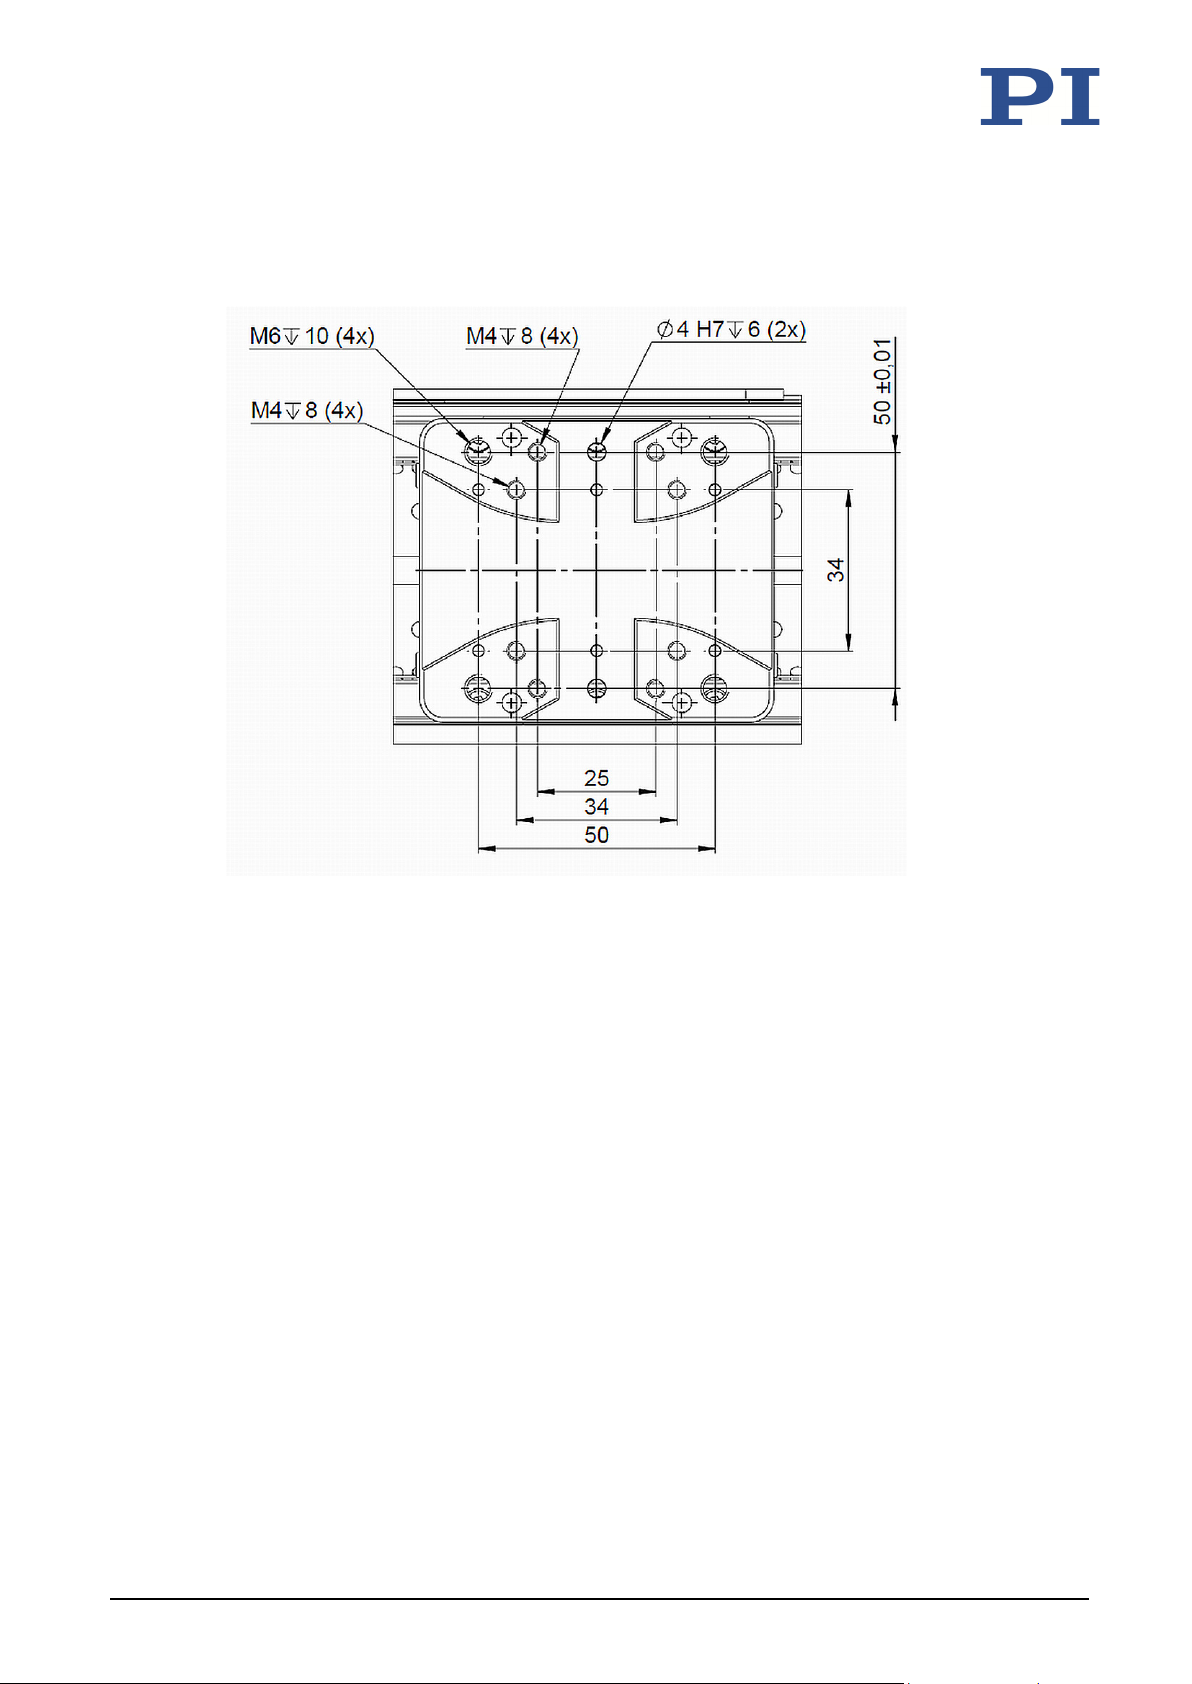
10.2.2 Hole Pattern of the Platform of the L-509
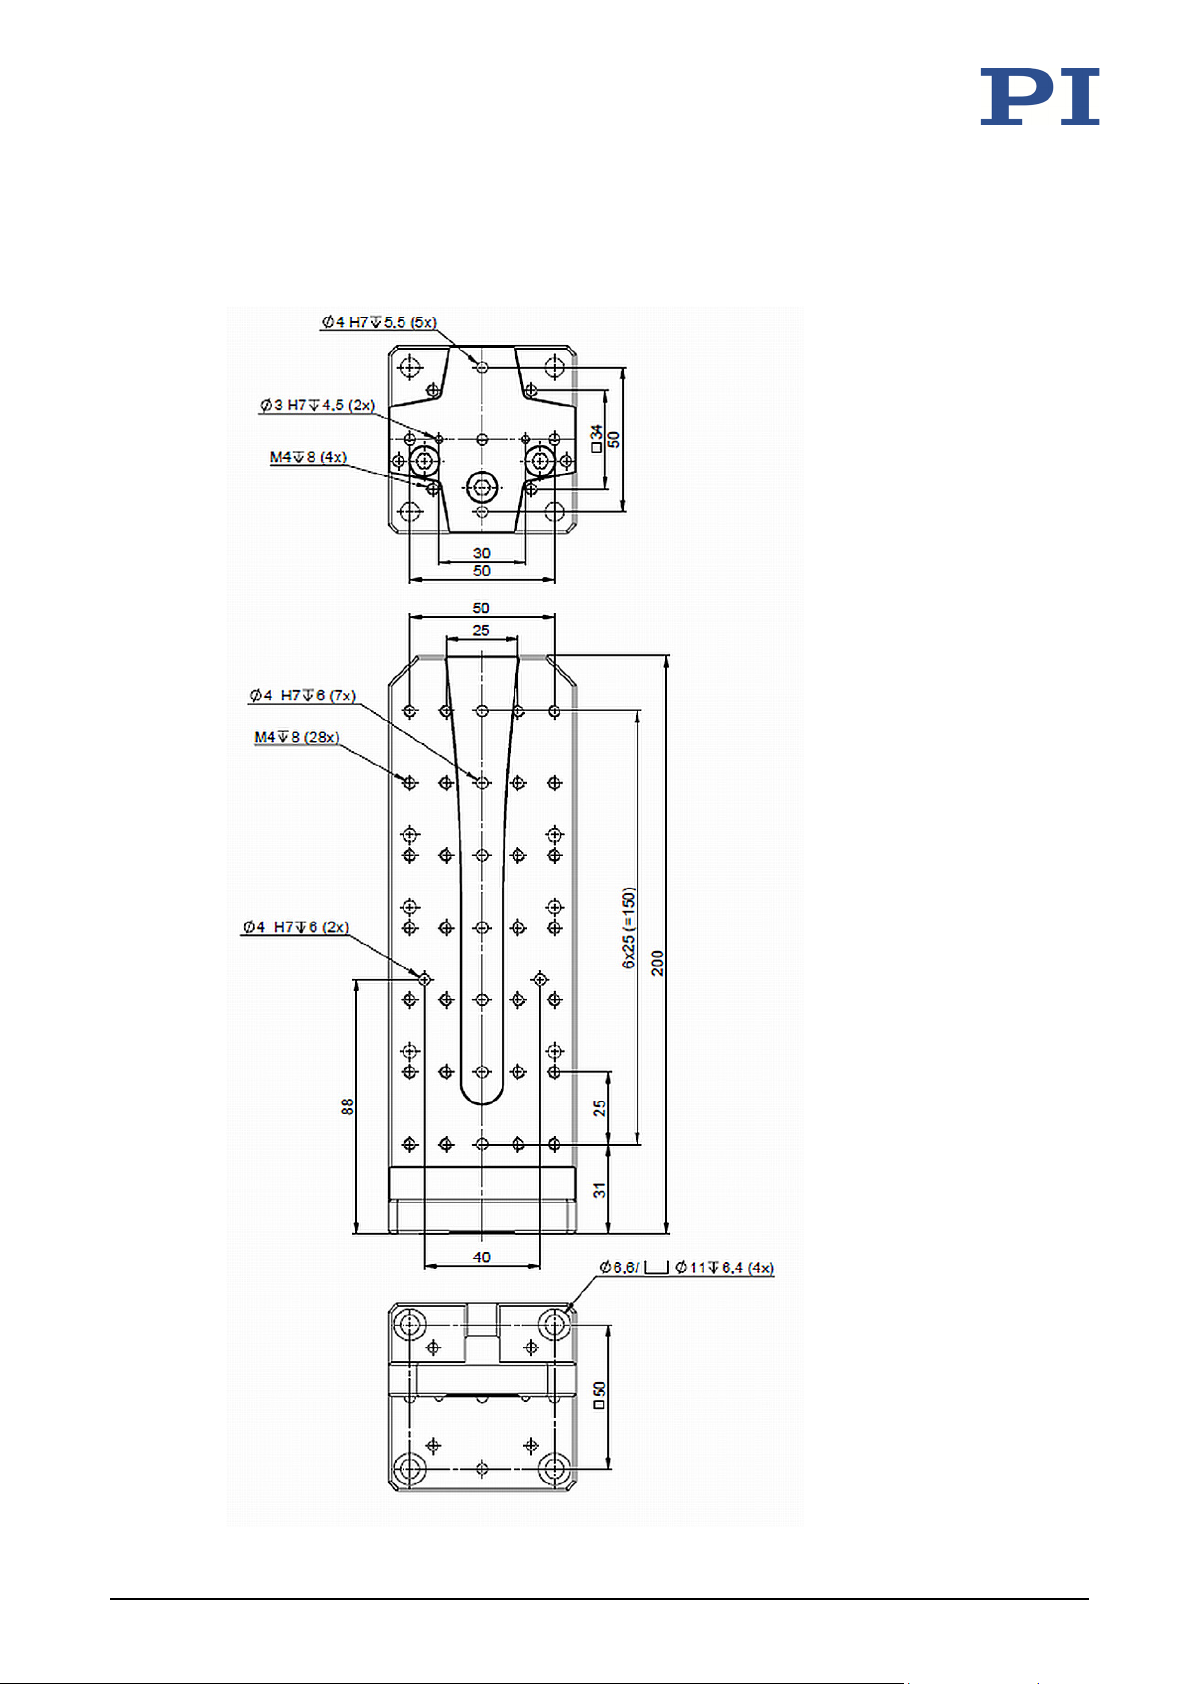
Dimensions in mm. Note that the decimal places are separated by a comma in the drawings.
Figure 10: Hole pattern of the platform
40 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 45
10 Technical Data
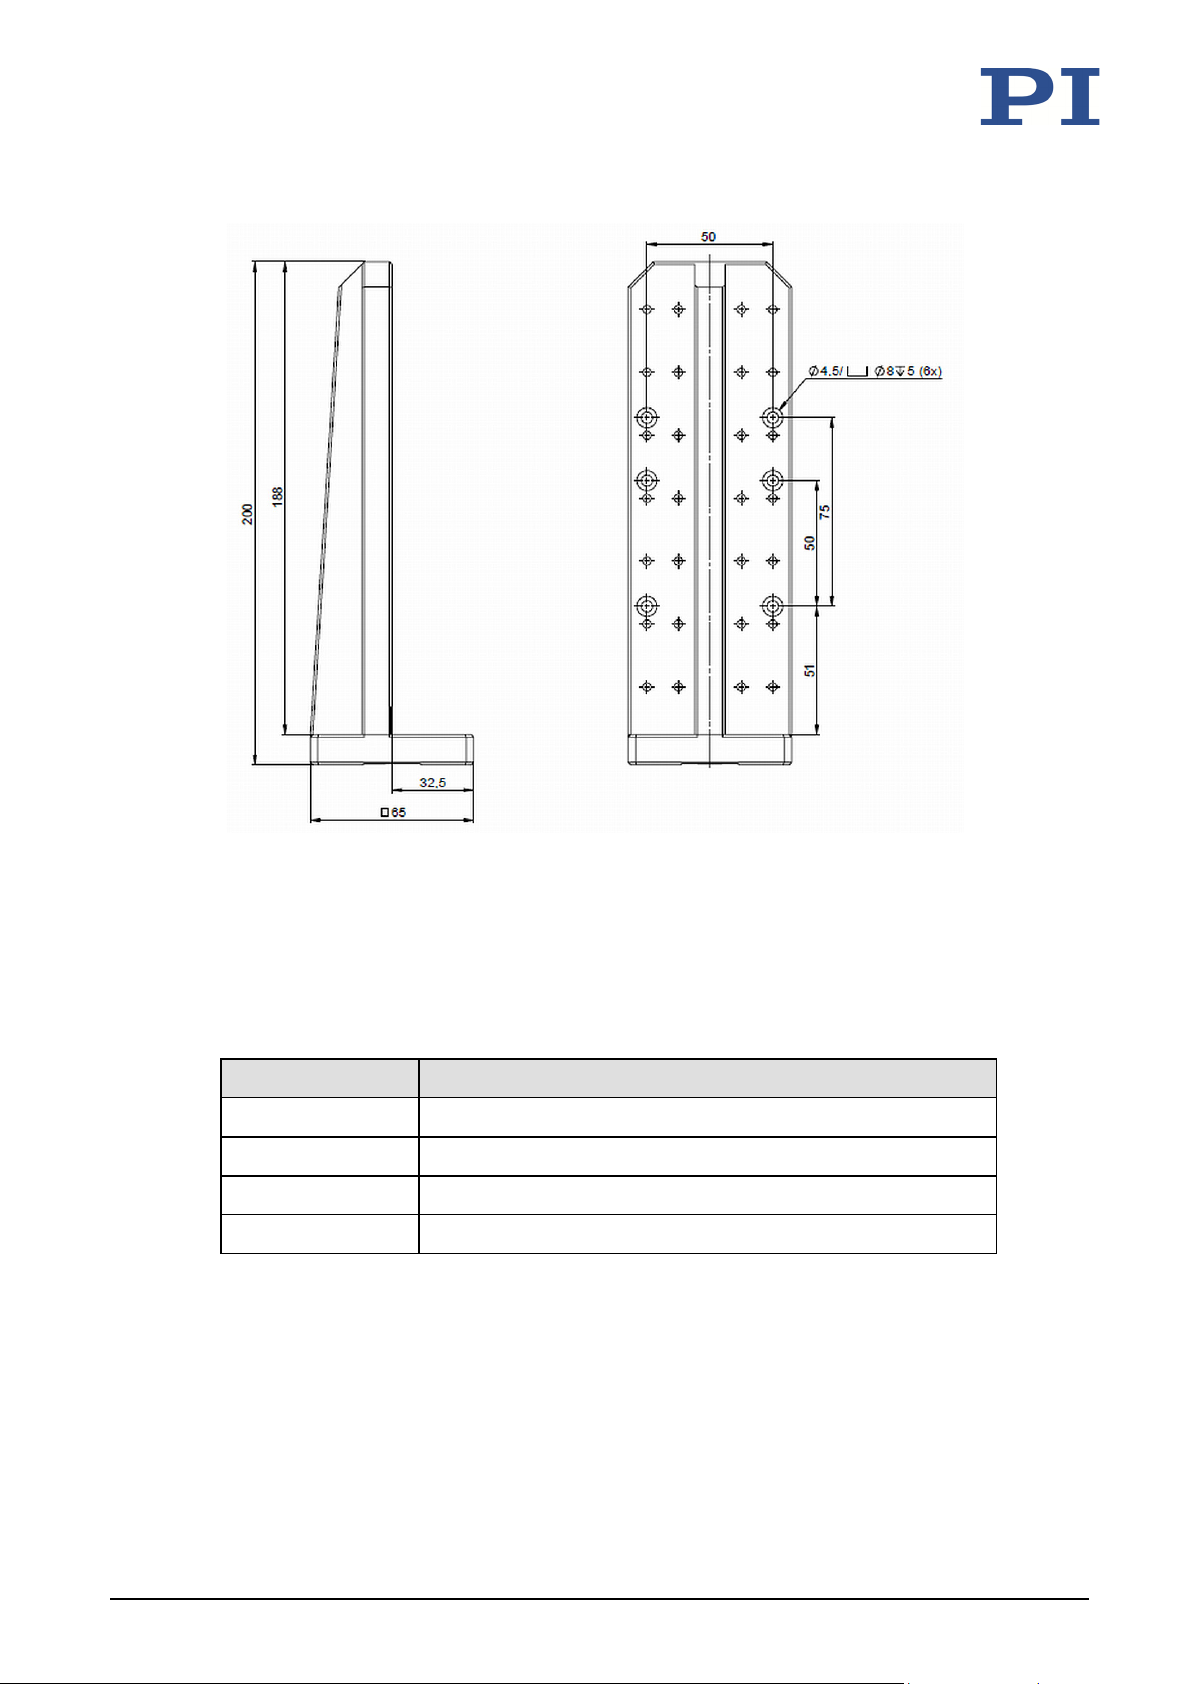
10.2.3 L-500.AV3-V9 Adapter Bracket
Dimensions in mm. Note that the decimal places are separated by a comma in the drawings.
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 41
Figure 11: L-500.AV3-V9 adapter bracket
Page 46
10 Technical Data
Figure 12: L-500.AV3-V9 adapter bracket
10.3 Tightening Torque for Screws, ISO 4762 - A2
The following tightening torques for screws according to ISO4762 (corresponds to DIN 912) - A2
may not be exceeded.
Value Maximum tightening torque
M3 1.5 Nm
M4 2 Nm
M5 2.5 Nm
M6 3 Nm
42 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 47
10 Technical Data
-
-
1
15
10.4 Pin Assignment
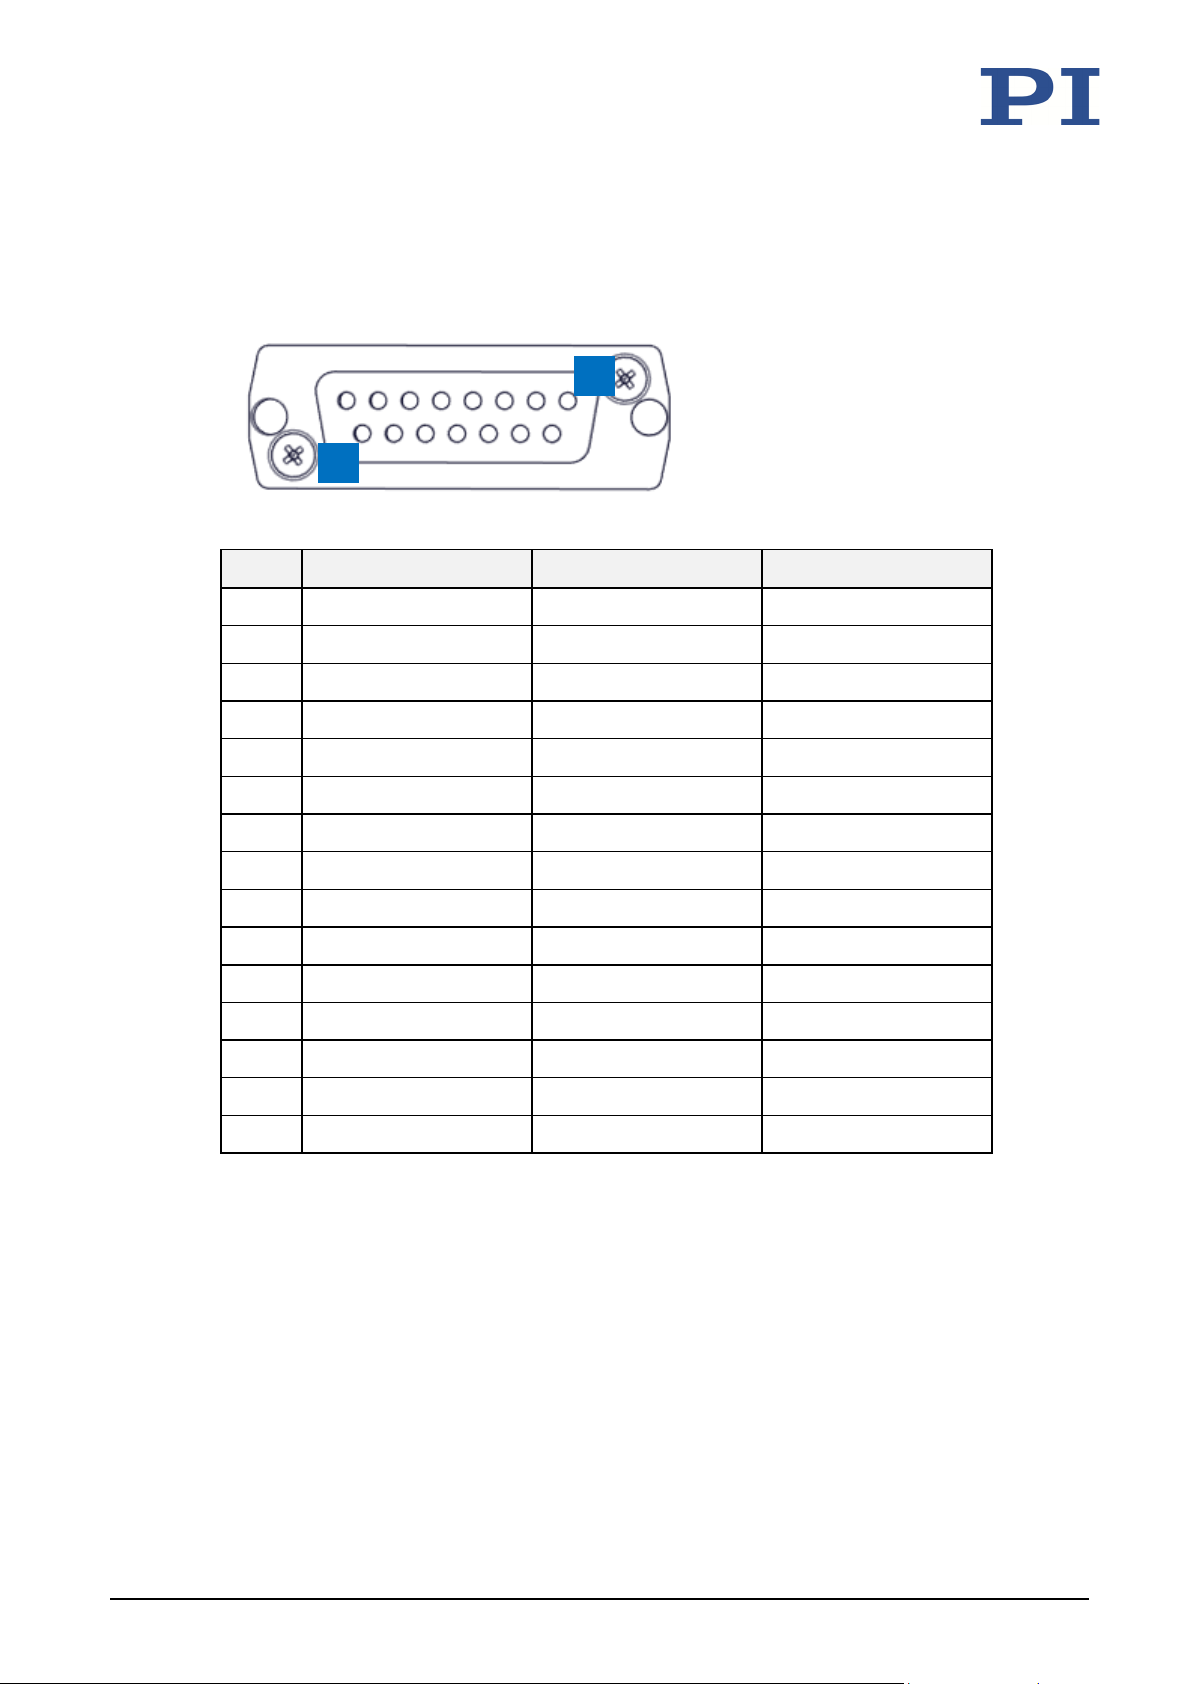
10.4.1 D-Sub 15 (Female)
Figure 13: D-Sub 15 (female) panel connector, mating side view
Pin Signal Strand Color Direction
1 Limit E1 (neg) Yellow Output
2 Limit GND Brown
3 - -
4 (Shield) - -
5 - - -
6 - - -
7 Motor B+ Blue Input
8 Motor A+ Red Input
9 - - -
10 Limit E2 (pos) Green Output
11 - - -
12 - - -
13 - - -
14 Motor B+ Green Input
15 Motor A- Yellow Input
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 43
Page 48
10 Technical Data
1
9
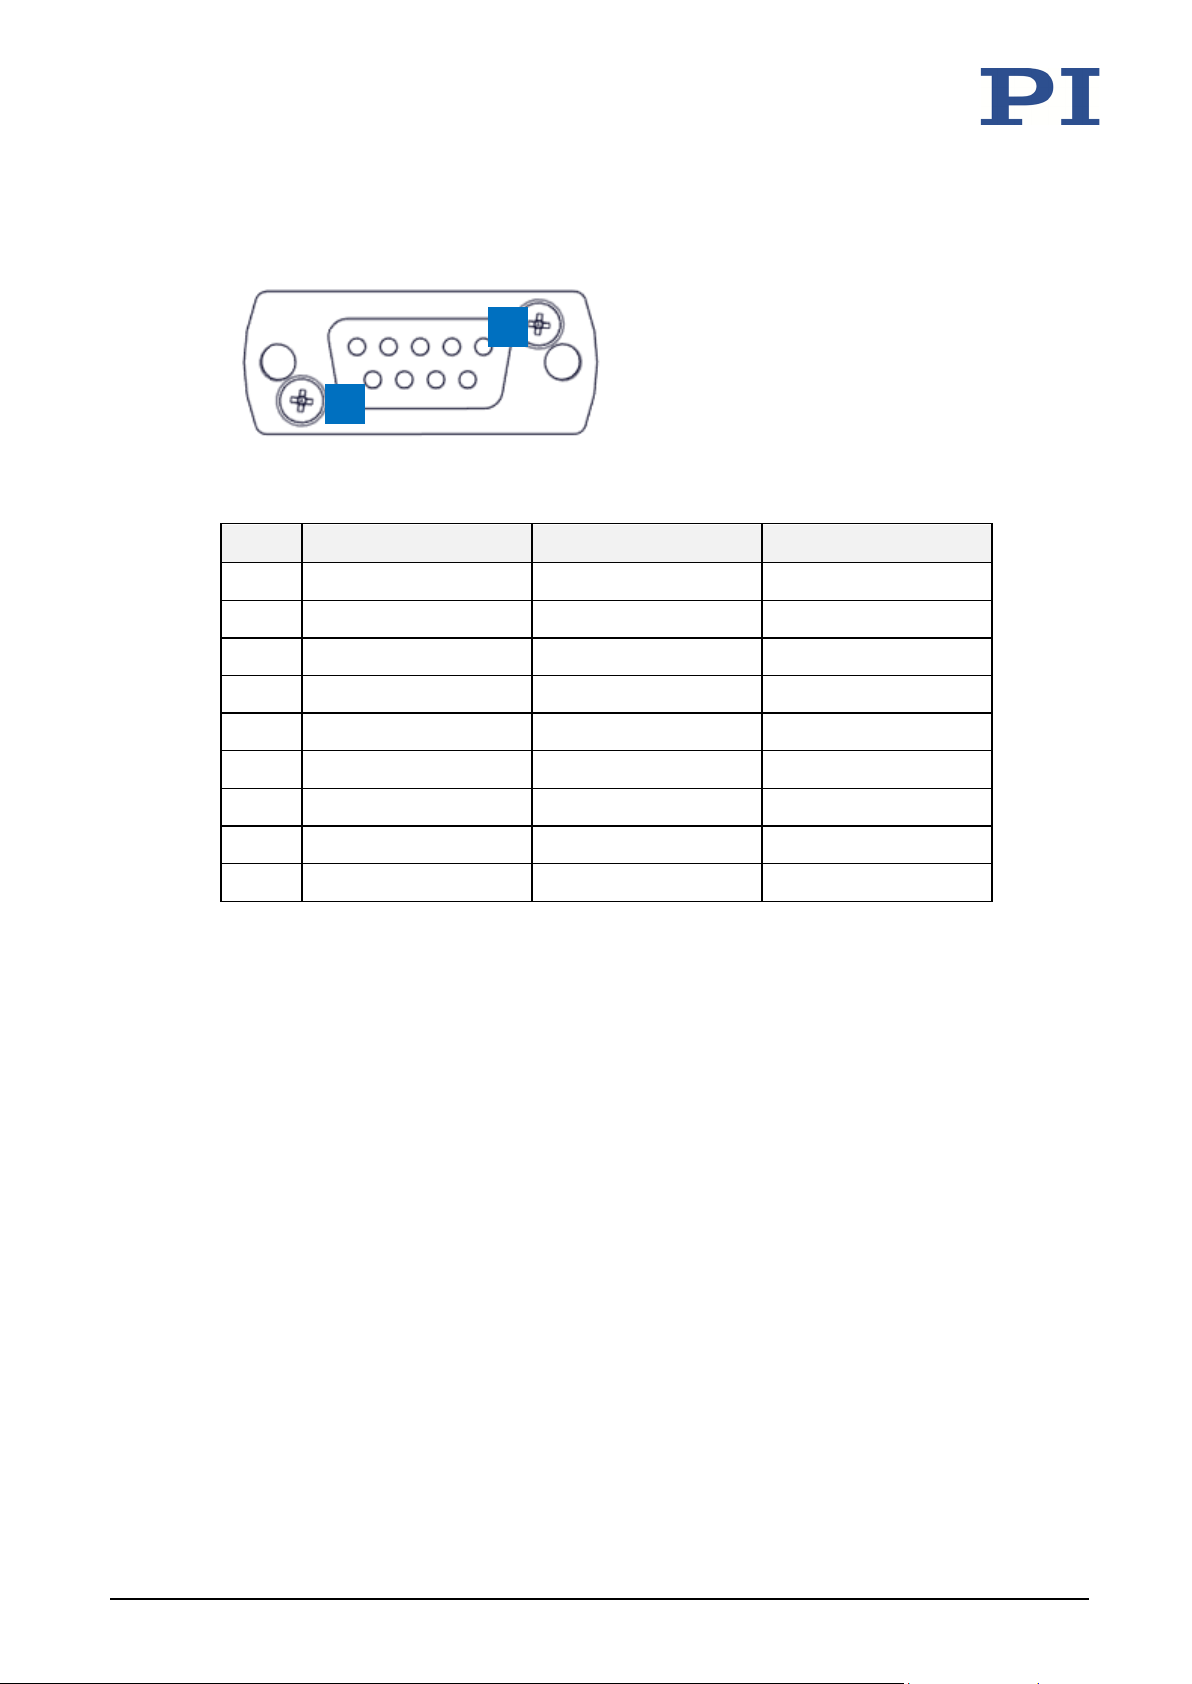
10.4.2 D-Sub 9 (Female, Only L 509.0x1311V7)
Figure 14: D-Sub 9 panel plug, mating side view
Pin Signal Strand Color Direction
1 Encoder Power (+ 5 V) Brown Input
2 Encoder GND White -
3 Encoder C+ Grey Output
4 Encoder B+ Blue Output
5 Encoder A+ Green Output
6 (Shield) - -
7 Encoder C- Pink Output
8 Encoder B- Red Output
9 Encoder A- Yellow Output
44 Version: 1.0.0 MP186E L-509 Vacuum-compatible positioner (1E-7 hPa)
Page 49
11 Old Equipment Disposal
11
Old Equipment Disposal
In accordance with EU law, electrical and electronic equipment may not be disposed of in EU
member states via the municipal residual waste.
Dispose of your old equipment according to international, national, and local rules and
regulations.
In order to fulfil the responsibility as the product manufacturer, PI miCos GmbH undertakes
environmentally correct disposal of all old PI miCos equipment made available on the market
after 13 August, 2005 without charge.
Any old PI miCos equipment can be sent free of charge to the following address:
PI miCos GmbH
Freiburger Strasse 30
79427 Eschbach, Germany
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 45
Page 50
Page 51
12 EU Declaration of Conformity
12
EU Declaration of Conformity
An EU Declaration of Conformity has been issued for the L-509 series in accordance with the
following European directives:
• EMC Directive
• RoHS Directive
The applied standards certifying the conformity are listed below.
• EMC: EN 61326-1
• Safety: EN 61010-1
• RoHS: EN 50581
L-509 Vacuum-compatible positioner (1E-7 hPa) MP186E Version: 1.0.0 47
 Loading...