

Page 1
STM17
Hardware Manual
Re-Order from
omegamation.com
Omegamation
TM
1-888-55-OMEGA
1-888-55-66342
1-888-55-66342
Re-Order from
omegamation.com
Omegamation
TM
1-888-55-OMEGA
1-888-55-66342
1-888-55-66342
920-0034 rev A
9/30/2010
Page 2
920-0034 rev A
9/30/2010
STM17 Hardware Manual
Contents
Introduction .................................................................................................................................................................................................................................3
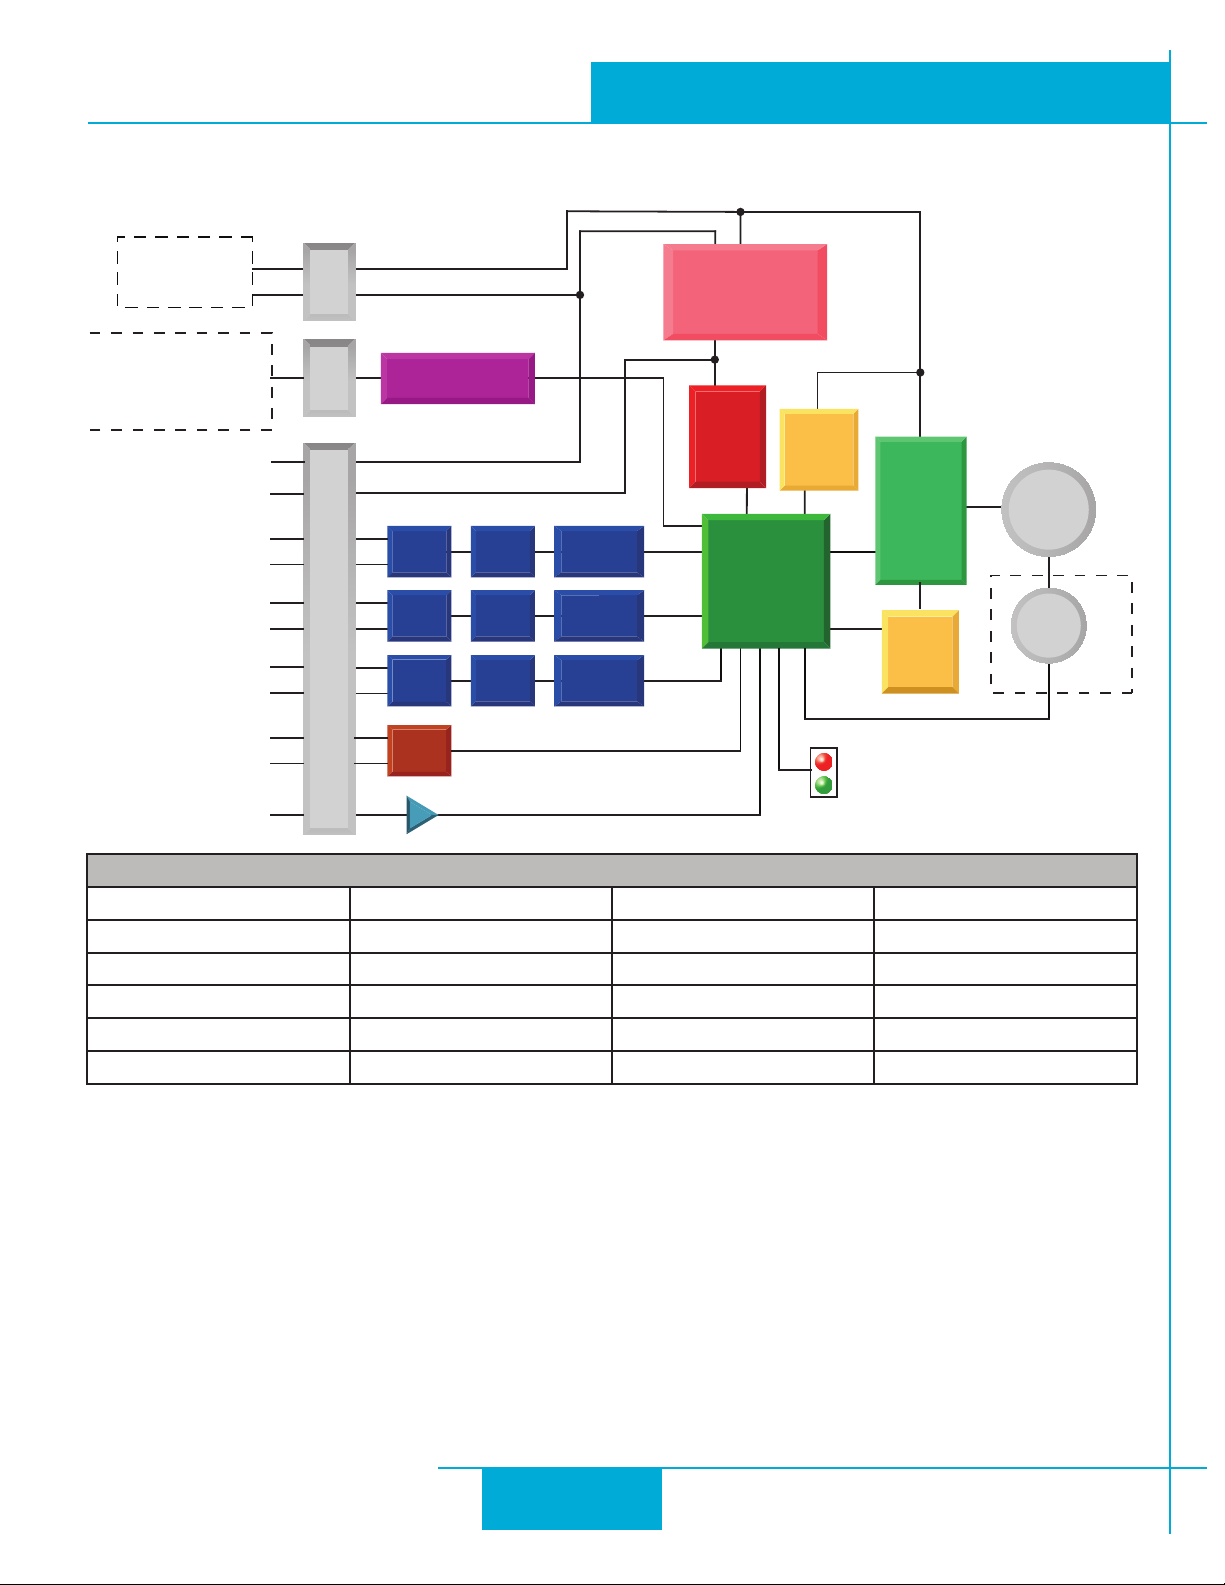
Block Diagram STM17S, STM17Q ..................................................................................................................................................................................4
Block Diagram STM17C ........................................................................................................................................................................................................5
Safety Instructions .....................................................................................................................................................................................................................6
Geing Started ...........................................................................................................................................................................................................................7
Installing Soware .............................................................................................................................................................................................................7
Mounting Hardware ........................................................................................................................................................................................................7
Additional Reading ..........................................................................................................................................................................................................7
Choosing a Power Supply ...................................................................................................................................................................................................8
Voltage Selection ...............................................................................................................................................................................................................8
Current Selection ...........................................................................................................................................................................................................10
Installation/Connections .....................................................................................................................................................................................................12
Connecting the Power Supply ................................................................................................................................................................................12
Connecting the STM17 Communications ........................................................................................................................................................13
Connecting to a PC using RS-232 ....................................................................................................................................................................13
Connecting to a host using RS-422/485 .......................................................................................................................................................13
Four-Wire Conguration ...................................................................................................................................................................................14
Two-Wire Conguration ...................................................................................................................................................................................15
Assigning RS-485 Addresses...........................................................................................................................................................................15
Connecting to an STM17 using USB ...............................................................................................................................................................15
STM17 Inputs and Outputs .............................................................................................................................................................................................17
e Step (STEP) and Direction (DIR) Inputs ...........................................................................................................................................................18
e Enable (EN) Digital Input.......................................................................................................................................................................................... 20
e Analog Input ................................................................................................................................................................................................................... 21
e Digital Output ................................................................................................................................................................................................................22
Reference Materials .............................................................................................................................................................................................................. 23
Mechanical Outlines.............................................................................................................................................................................................................23
Technical Specications .....................................................................................................................................................................................................24
Torque-Speed Curves ........................................................................................................................................................................................................ 26
Drive/Motor Heating ........................................................................................................................................................................................................... 30
Mating Connectors and Accessories .......................................................................................................................................................................... 32
LED Error Codes ..................................................................................................................................................................................................................... 33
Contacting Applied Motion Products .......................................................................................................................................................................33
2
Page 3
920-0034 rev A
STM17 Hardware Manual
9/30/2010
Introduction
ank you for selecting the Applied Motion Products STM17 Drive+Motor. We hope our dedication to performance,
quality and economy will make your motion control project successful. If there’s anything we can do to improve our products or help you use them beer, please call or fax. We’d like to hear from you. Our phone number is (800) 525-1609, or
you can reach us by fax at (831) 761-6544. You can also email [email protected].
Features
Programmable, micro-stepping digital step motor and driver in an integrated package•
Operates from a 12 to 48 volt DC power supply•
Pulse/Direction, CW Pulse/CCW Pulse, or AB Quadrature •
Velocity (Oscillator) mode•
Streaming SCL commands•
Stored Q programs (-Q, -C models only)•
Encoder following (-Q models only)•
RS-232 or RS-422/485 communication (-S, -Q)•
CANopen DS301, DSP402 (-C only)•
Optional, internal encoder feedback•
Available torque up to 68 oz-in (0.48 N-m)•
Digital input ltering •
3 optically isolated digital inputs, 5 to 24 volts •
Optically isolated digital output, 30V 100mA •
12 bit analog input for speed and position control, 0 to 5 volts•
Step input signal smoothing (microstep emulation)•
Anti-resonance•
Electronic damping•
3
Page 4
MOSFET
PWM
Power
Amplifier
12-48 VDC
External
Power Supply
Voltage
Temp
Det.
Over
Current
Det.
motor
encoder
5 Volt DC
Power Supply
DSP
Driver
Controller
3.3VDC
Internal
Logic
Supply
Optical
Iso
I/O Connector
+
Optical
Iso
Optical
Iso
STEP+
+5VDC (50mA MAX)
GND
Digital
Filter
Digital
Filter
Digital
Filter
Software
Filter
Software
Filter
Software
Filter
Status
AIN
Optical
Iso
RS-232 or RS-485
Comm
Conn
Power
Conn
GND
+5V
STEP-
DIR+
DIR-
EN+
EN-
OUT+
OUT-
RS-232
TX, RX, GND, +5V
or
RS-485
RX+, RX-, TX+, TX-, GND
-
Optional
920-0034 rev A
9/30/2010
Block Diagram STM17S, STM17Q
STM17 Hardware Manual
IO Functions (congure in software)
STEP (5 to 24 Volts) DIR (5 to 24 Volts) EN (5 to 24 Volts) OUT (30V, 80mA)
Step Input Dir Input Enable Input Brake Output
Jog CW Jog CCW Reset Input Alarm Output
Limit CW Limit CCW Change Speed Motion Output
Start/Stop General Purpose General Purpose Tach Output
General Purpose General Purpose
4
Page 5
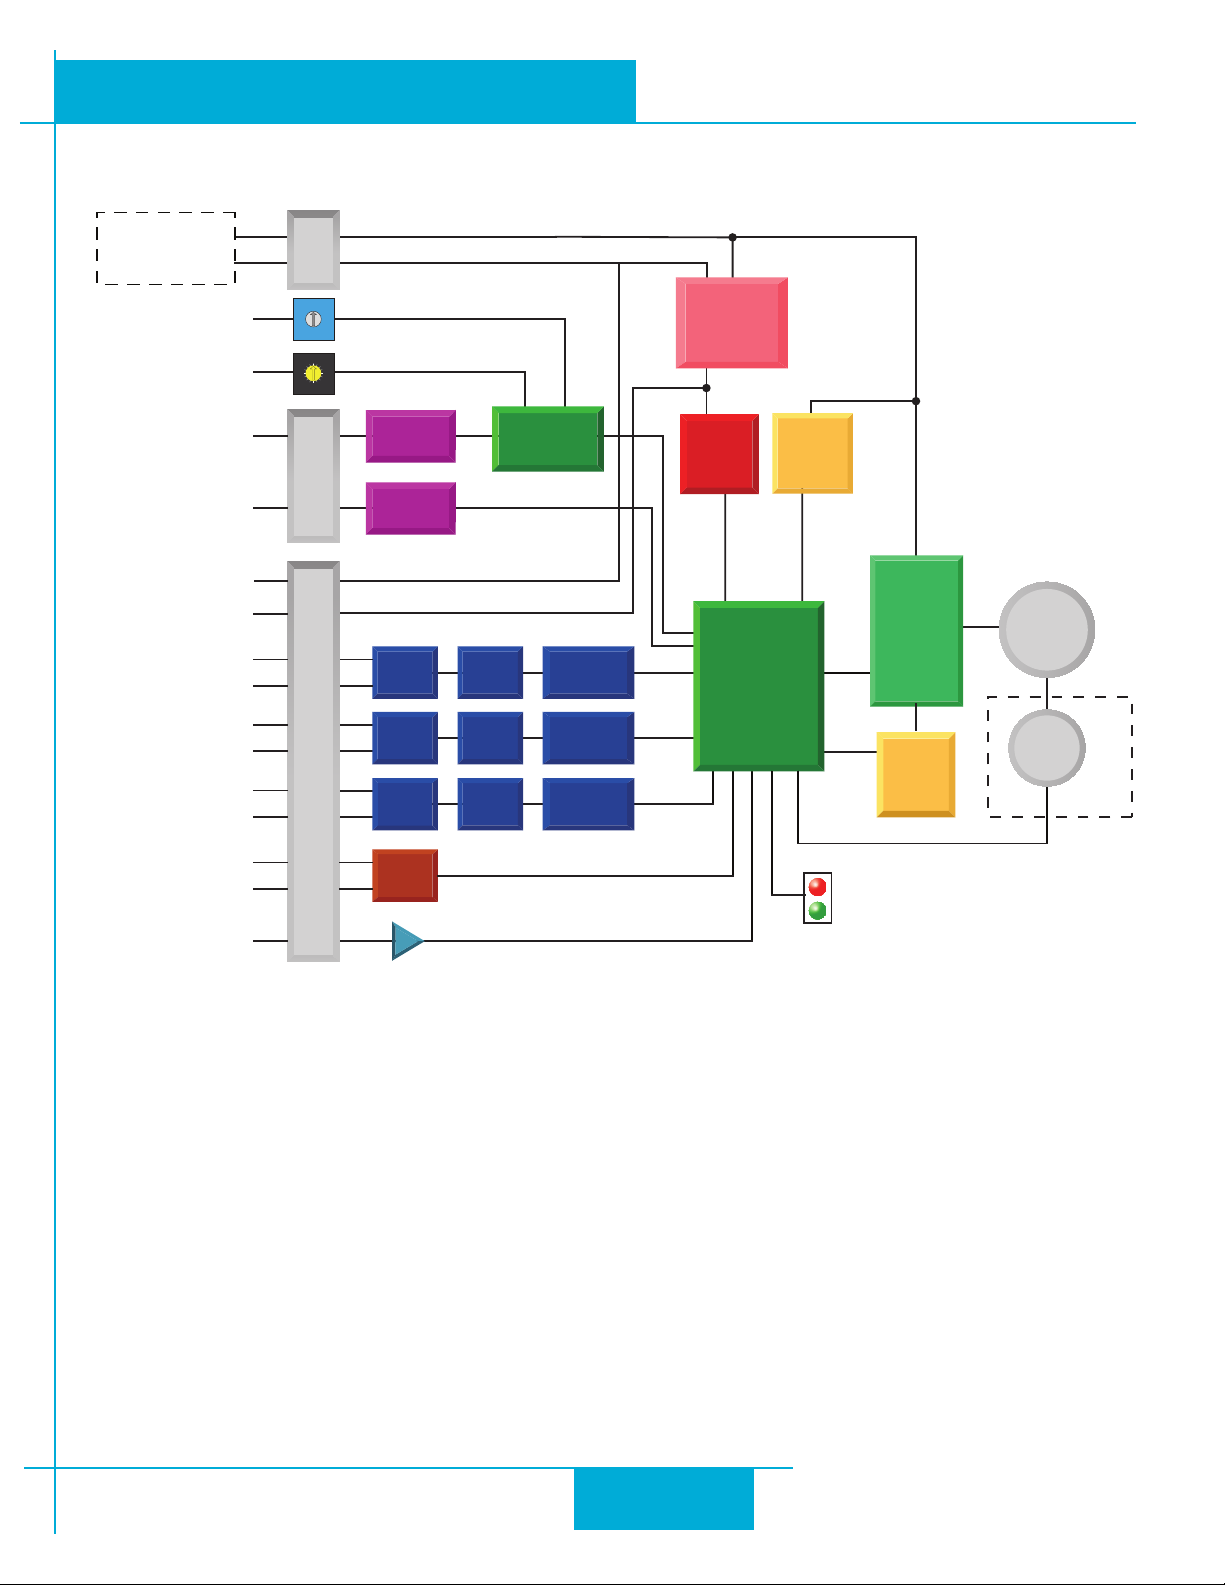
MOSFET
PWM
Power
Amplifier
12-48 VDC
External
Power Supply
Voltage
Temp
Monitor
Over
Current
Monitor
motor
encoder
5 VDC
Power
Supply
DSP
Driver
Controller
3.3VDC
Power
Supply
Optical
Iso
I/O Connector
+
Optical
Iso
Optical
Iso
STEP+
+5VDC (50mA MAX)
GND
Digital
Filter
Digital
Filter
Digital
Filter
Software
Filter
Software
Filter
Software
Filter
Status
AIN
Optical
Iso
RS-232
Comm
Conn
Power
Conn
GND
To PC
(for configuration)
+5V
STEP-
DIR+
DIR-
EN+
EN-
OUT+
OUT-
CAN2.0b
To CANopen
Host
Node ID
Bit Rate
-
Optional
CANopen
Controller
4
3
2
1
0
F
E
D
C
B
A
9
8
7
6
5
5
0
4
9
3
8
2
7
1
6
STM17 Hardware Manual
Block Diagram STM17C
920-0034 rev A
9/30/2010
5
Page 6
920-0034 rev A
9/30/2010
STM17 Hardware Manual
Safety Instructions
Only qualied personnel are permied to transport, assemble, commission, and maintain this equipment. Properly qualied personnel are persons who are familiar with the transport, assembly, installation, commissioning and operation of
motors, and who have the appropriate qualications for their jobs. e qualied personnel must know and observe the
following standards and regulations:
IEC 364 resp. CENELEC HD 384 or DIN VDE 0100
IEC report 664 or DIN VDE 0110
National regulations for safety and accident prevention or VBG 4
To minimize the risk of potential safety problems, you should follow all applicable local and national codes that regulate
the installation and operation of your equipment. ese codes vary from area to area and it is your responsibility to determine which codes should be followed, and to verify that the equipment, installation, and operation are in compliance
with the latest revision of these codes.
Equipment damage or serious injury to personnel can result from the failure to follow all applicable codes and standards.
We do not guarantee the products described in this publication are suitable for your particular application, nor do we
assume any responsibility for your product design, installation, or operation.
•Readallavailabledocumentationbeforeassemblyandcommissioning.Incorrecthandlingofproductsinthismanual
can result in injury and damage to persons and machinery. Strictly adhere to the technical information on the installation
requirements.
•Itisvitaltoensurethatallsystemcomponentsareconnectedtoearthground.Electricalsafetyisimpossiblewithouta
low-resistance earth connection.
•eSTM17drivescontainelectrostaticallysensitivecomponentsthatcanbedamagedbyincorrecthandling.Discharge yourself before touching the product. Avoid contact with high insulating materials (articial fabrics, plastic lm,
etc.). Place the product on a conductive surface.
•Duringoperationkeepallcoversandcabinetdoorsshut.Otherwise,therearedeadlyhazardsthatcouldpossibly
cause severe damage to health or the product.
•Inoperation,dependingonthedegreeofenclosureprotection,theproductcanhavebarecomponentsthatarelive
or have hot surfaces. Control and power cables can carry a high voltage even when the motor is not rotating.
•Neverpulloutorplugintheproductwhilethesystemislive.ereisadangerofelectricarcinganddangertopersons and contacts.
•Aerpoweringdowntheproduct,waitatleasttenminutesbeforetouchinglivesectionsoftheequipmentorundoing
connections (e.g., contacts, screwed connections). Capacitors can store dangerous voltages for long periods of time aer
power has been switched o. To be safe, measure the contact points with a meter before touching.
Be alert to the potential for personal injury. Follow the recommended precautions and safe operating practices included
with the alert symbols. Safety notices in this manual provide important information. Read and be familiar with these
instructions before aempting installation, operation, or maintenance. e purpose of this section is to alert users to
possible safety hazards associated with this equipment and the precautions that need to be taken to reduce the risk of
personal injury and damage to the equipment.
Failure to observe these precautions could result in serious bodily injury, damage to the equipment, or operational difculty.
6
Page 7
STM17 Hardware Manual
Geing Started
e following items are needed:
a 12 - 48 volt DC power supply, see the section entitled “Choosing a Power Supply” for help in choosing one•
a small at blade screwdriver for tightening the connectors (included)•
a PC running Microso Windows 98, 2000, NT, Me, XP, Vista, or Windows 7•
the CD that was included with your STM17•
a programming cable (included with RS-232 models)•
Installing Soware
Before using the STM17 integrated motor and
sary:
Install the ST Congurator soware from the CD. •
Launch the soware by clicking Start...Programs...Applied Motion Products. •
Connect the drive to the PC using the programming cable. When using RS-422/485, the drive must be set up in a •
4-Wire conguration (see “Connecting to a host using RS-422/485”.)
Connect the drive to the power supply. See instructions.•
Apply power to the drive.•
e soware will recognize the drive and display the model and rmware version. At this point, it is ready for use.•
If you are using an STM17Q and plan to create a Q program to be stored in the drive, you will also need to install •
Programmer
.
ST Congurator
920-0034 rev A
9/30/2010
soware in an application, the following steps are neces-
Q
Mounting Hardware
As with any step motor, the STM17 must be mounted so as to provide maximum heat sinking and airow. Keep enough
space around the unit to allow for airow.
Never use the drive where there is no airow or where other devices cause the surrounding air to be more than 40°C (104°F).
Never put the drive where it can get wet.
Never use the drive where metal or other electrically conductive particles can inltrate
the drive.
Always provide airow around the STM17.
Additional Reading
To learn more about
To learn more about the Q and SCL languages, please read the
www.applied-motion.com.
ST Congurator
, please refer to the built-in help.
Host Command Reference
, available on your CD and at
7
Page 8
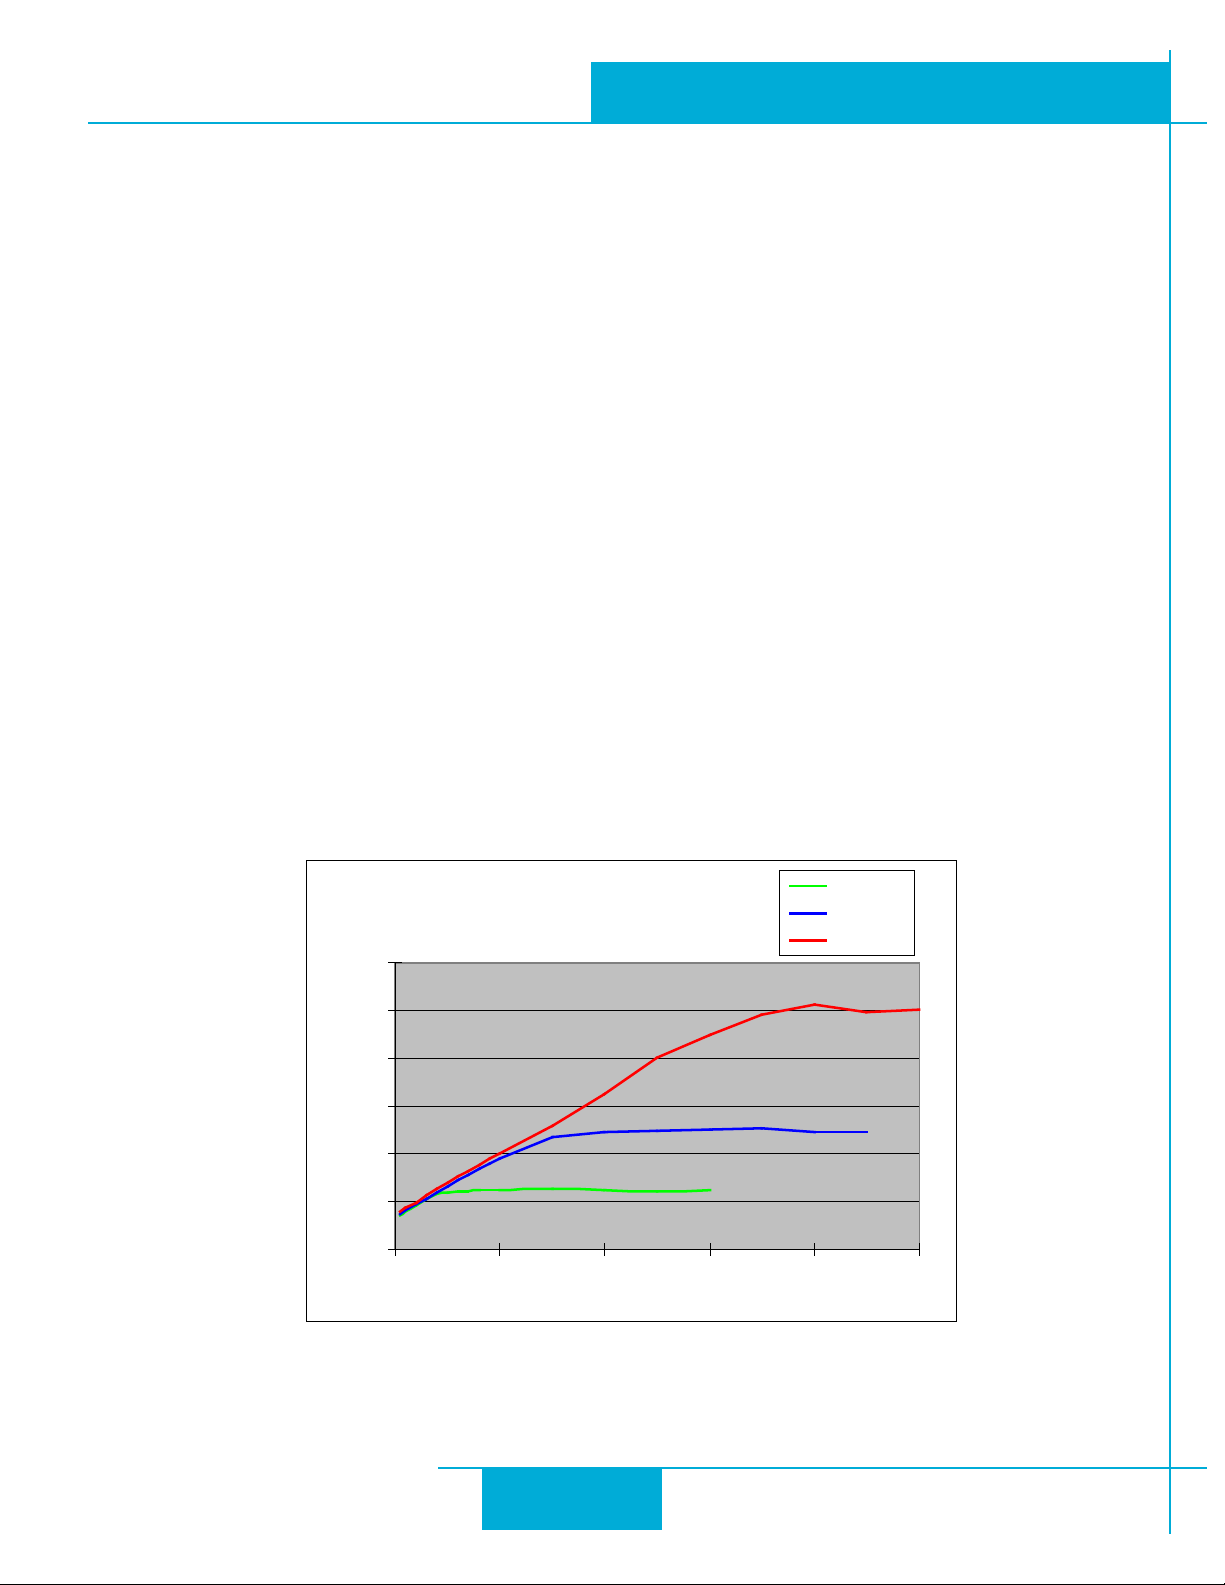
STM17S-1AN Wattage vs Speed
1.8 Amps @ Ambient of 40°C
80 x 80x 6(mm) Alumin um Plate
0
10
20
30
40
50
60
0 10 20 30 40 50
Speed(RPS)
Watts
12V W atts
24V W atts
48V W atts
920-0034 rev A
9/30/2010
STM17 Hardware Manual
Choosing a Power Supply
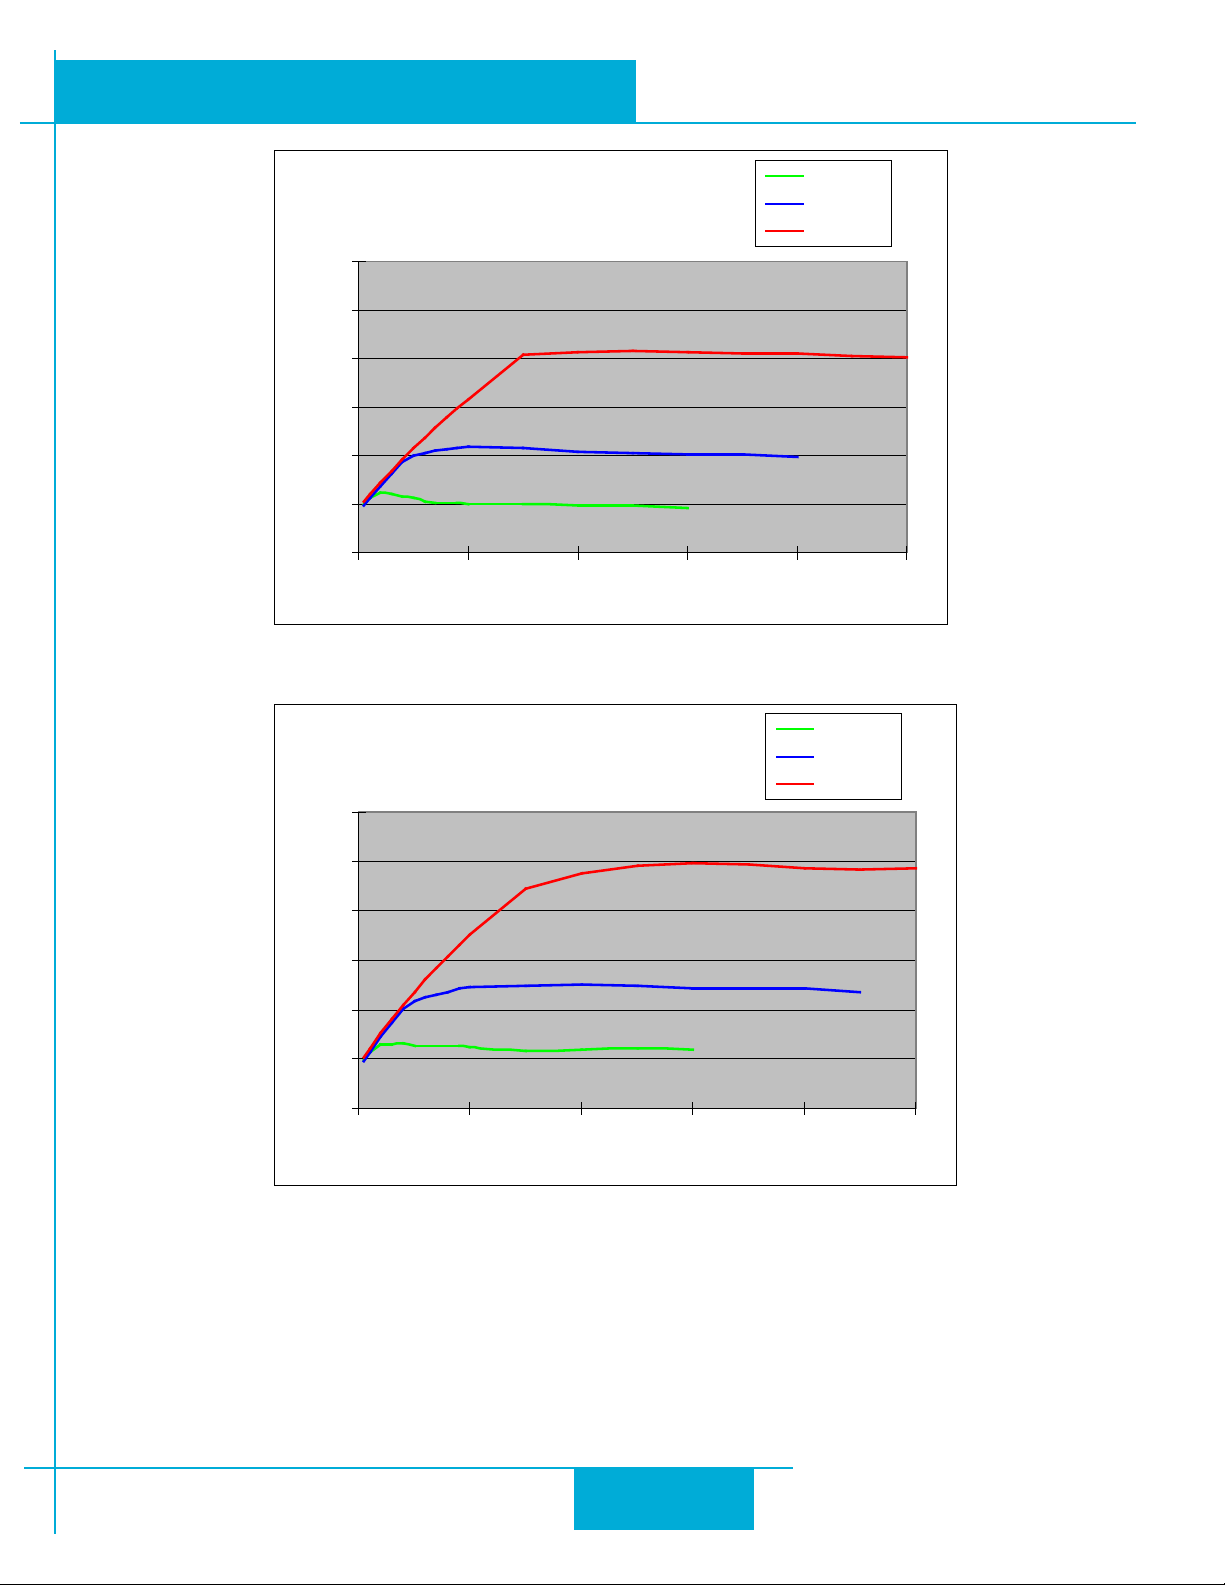
e main considerations when choosing a power supply are the voltage and current requirements for the application.
Voltage Selection
e STM17 is designed to give optimum performance between 12 and 48 Volts DC. Choosing the voltage depends on
the performance needed and motor/drive heating that is acceptable and/or does not cause a drive over-temperature.
Higher voltages will give higher speed performance but will cause the STM17 to produce higher temperatures. Using
power supplies with voltage outputs that are near the drive maximum may signicantly reduce the operational dutycycle.
e extended range of operation can be as low as 10 VDC minimum to as high as 55 VDC maximum. When operating
below 12 VDC, the power supply input may require larger capacitance to prevent under-voltage and internal-supply
alarms. Current spikes may make supply readings erratic. e supply input cannot go below 12 VDC for reliable operation. Absolute minimum power supply input is 10 VDC. If the Input supply drops below 10 VDC the low voltage alarm
will be triggered. is will not fault the drive, but the drive will likely power down.
Absolute maximum power supply input is 55 VDC at which time an over-voltage alarm and fault will occur. When using
a power supply that is regulated and is near the drive maximum voltage of 55 VDC, a voltage clamp may be required to
prevent over-voltage when regeneration occurs. e RC-050 Regeneration Clamp is recommended for the STM17 in this
situation. When using an unregulated power supply, make sure the no-load voltage of the supply does not exceed the
drive’s maximum input voltage of 55 VDC.
e charts below show the heat output, in was, of the drive at various speeds and voltages. See the section on “Duty
Cycle Heating” in the Reference Materials for more information.
8
Page 9
STM17S-2AN Wattage vs Speed
1.8 Amps @ Ambient o f 40°C
80 x 80x 6(mm) Aluminum Plate
0
10
20
30
40
50
60
0 10 20 30 40 50
Speed(RPS)
Watts
12V W atts
24V W atts
48V W atts
STM17S-3AN Wattage vs Speed
1.8 Amps @ Ambient o f 40°C
80 x 80x 6(mm) Aluminum Plate
0
10
20
30
40
50
60
0 10 20 30 40 50
Speed(RPS)
Watts
12V W atts
24V W atts
48V W atts
STM17 Hardware Manual
920-0034 rev A
9/30/2010
9
Page 10
0.6
0.8
1.0
1.2
pply Current A)
STM17X-1
12V 24V 48V
0.0
0.2
0.4
0.6
0.8
1.0
1.2
0 10 20 30 40 50
Max Supply Current (A)
rps
STM17X-1
12V 24V 48V
920-0034 rev A
9/30/2010
STM17 Hardware Manual
Current Selection
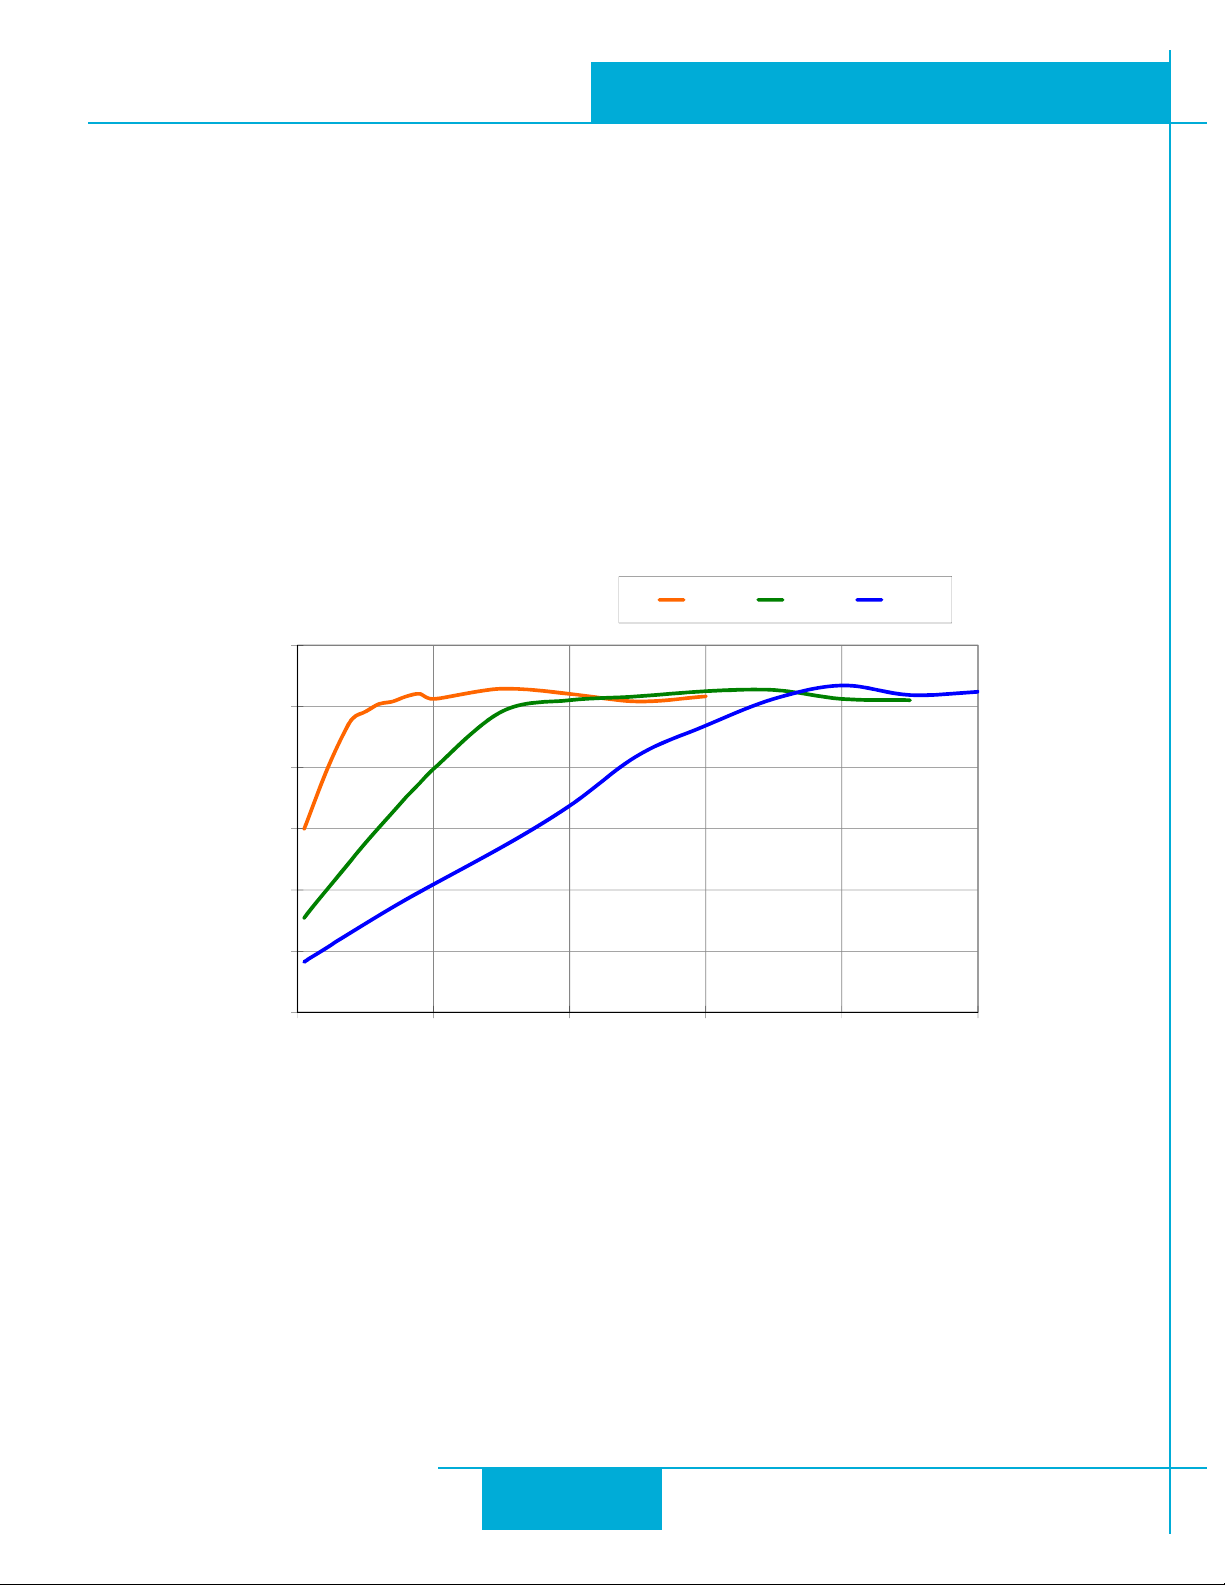
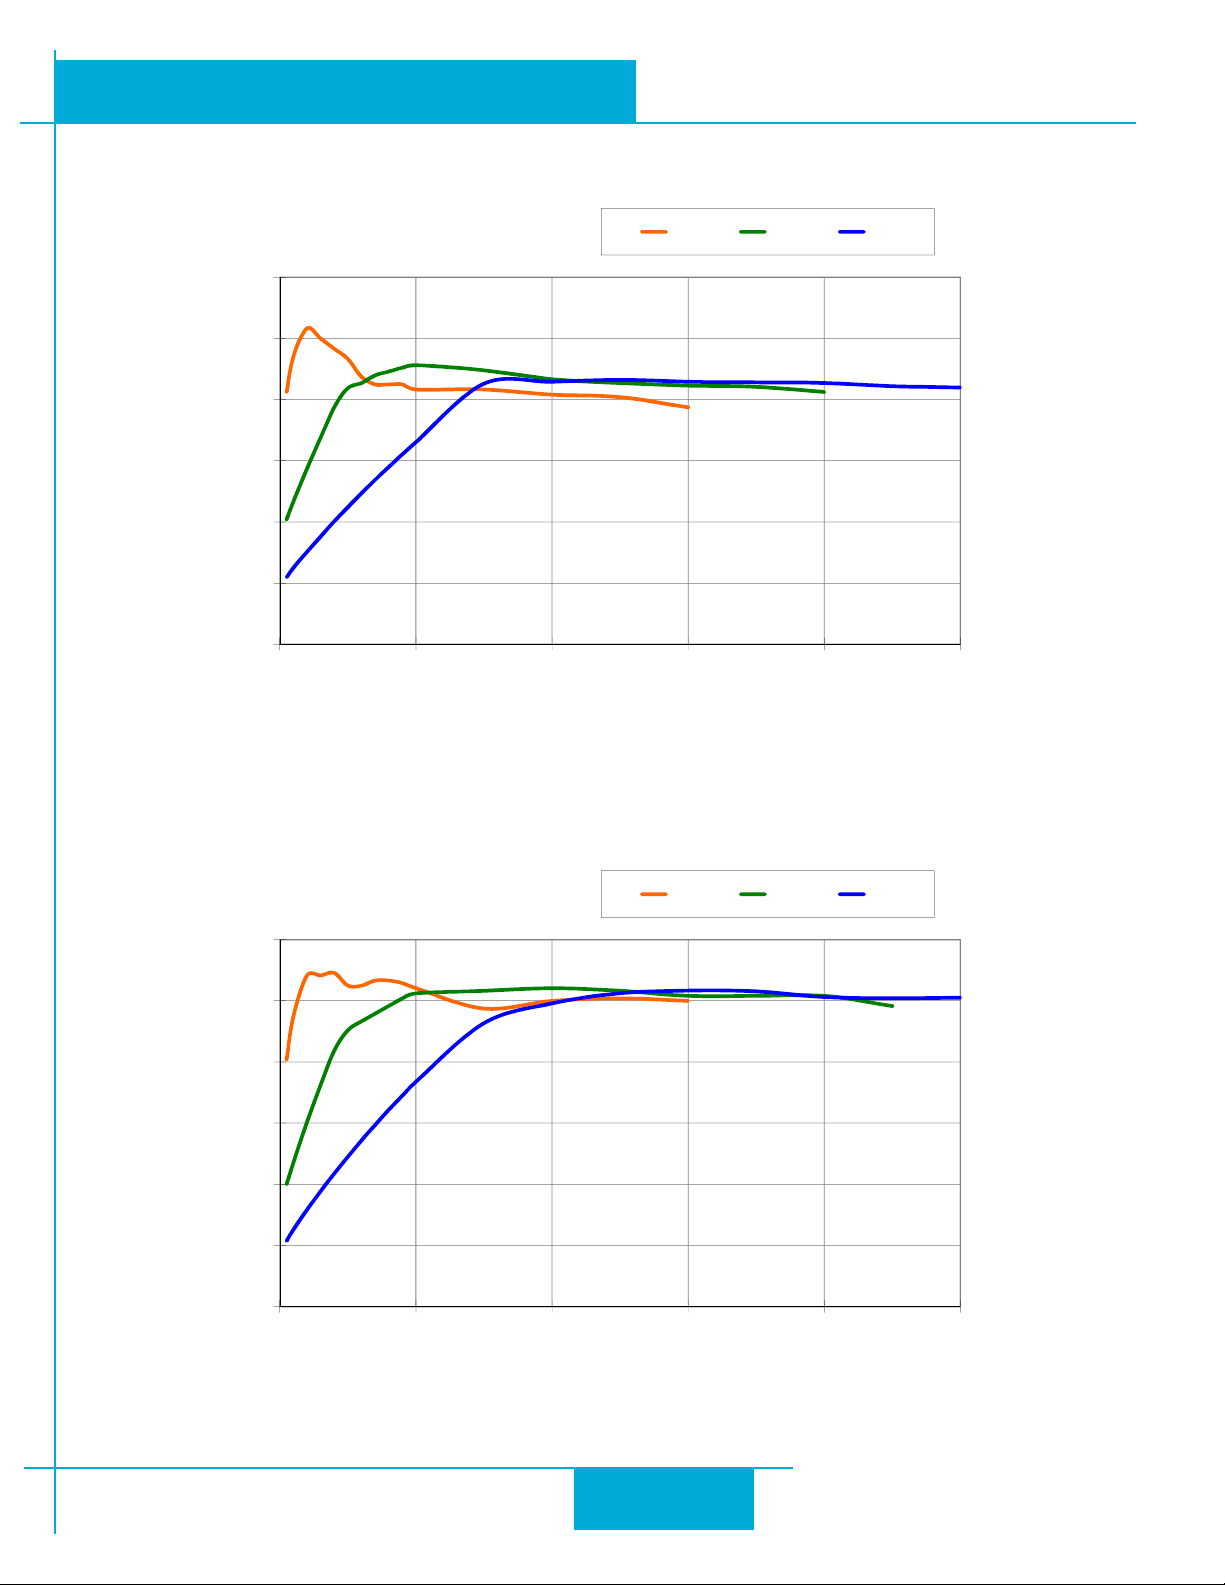
e maximum supply currents required by the STM17 are shown in the charts below at dierent power supply voltage
inputs. e STM17 power supply current is lower than the winding currents because it uses switching ampliers to convert a high voltage and low current into lower voltage and higher current. e more the power supply voltage exceeds
the motor voltage, the less current will be required from the power supply.
It is important to note that the current draw is signicantly dierent at higher speeds depending on the torque load to
the motor. Estimating how much current is necessary may require a good analysis of the load the motor will encounter.
Note: all curves were measured at 20,000 steps/rev, 1.8A motor current, maximum torque load
10
Page 11
0.6
0.8
1.0
1.2
pply Current (A)
STM17X-3
12V 24V 48V
0.0
0.2
0.4
0.6
0.8
1.0
1.2
0 10 20 30 40 50
Max Supply Current (A)
rps
STM17X-3
12V 24V 48V
0.6
0.8
1.0
1.2
pply Current A)
STM17X-2
12V 24V 48V
0.0
0.2
0.4
0.6
0.8
1.0
1.2
0 10 20 30 40 50
Max Supply Current (A)
rps
STM17X-2
12V 24V 48V
STM17 Hardware Manual
920-0034 rev A
9/30/2010
11
Page 12
920-0034 rev A
9/30/2010
STM17 Hardware Manual
Installation/Connections
Connecting the Power Supply
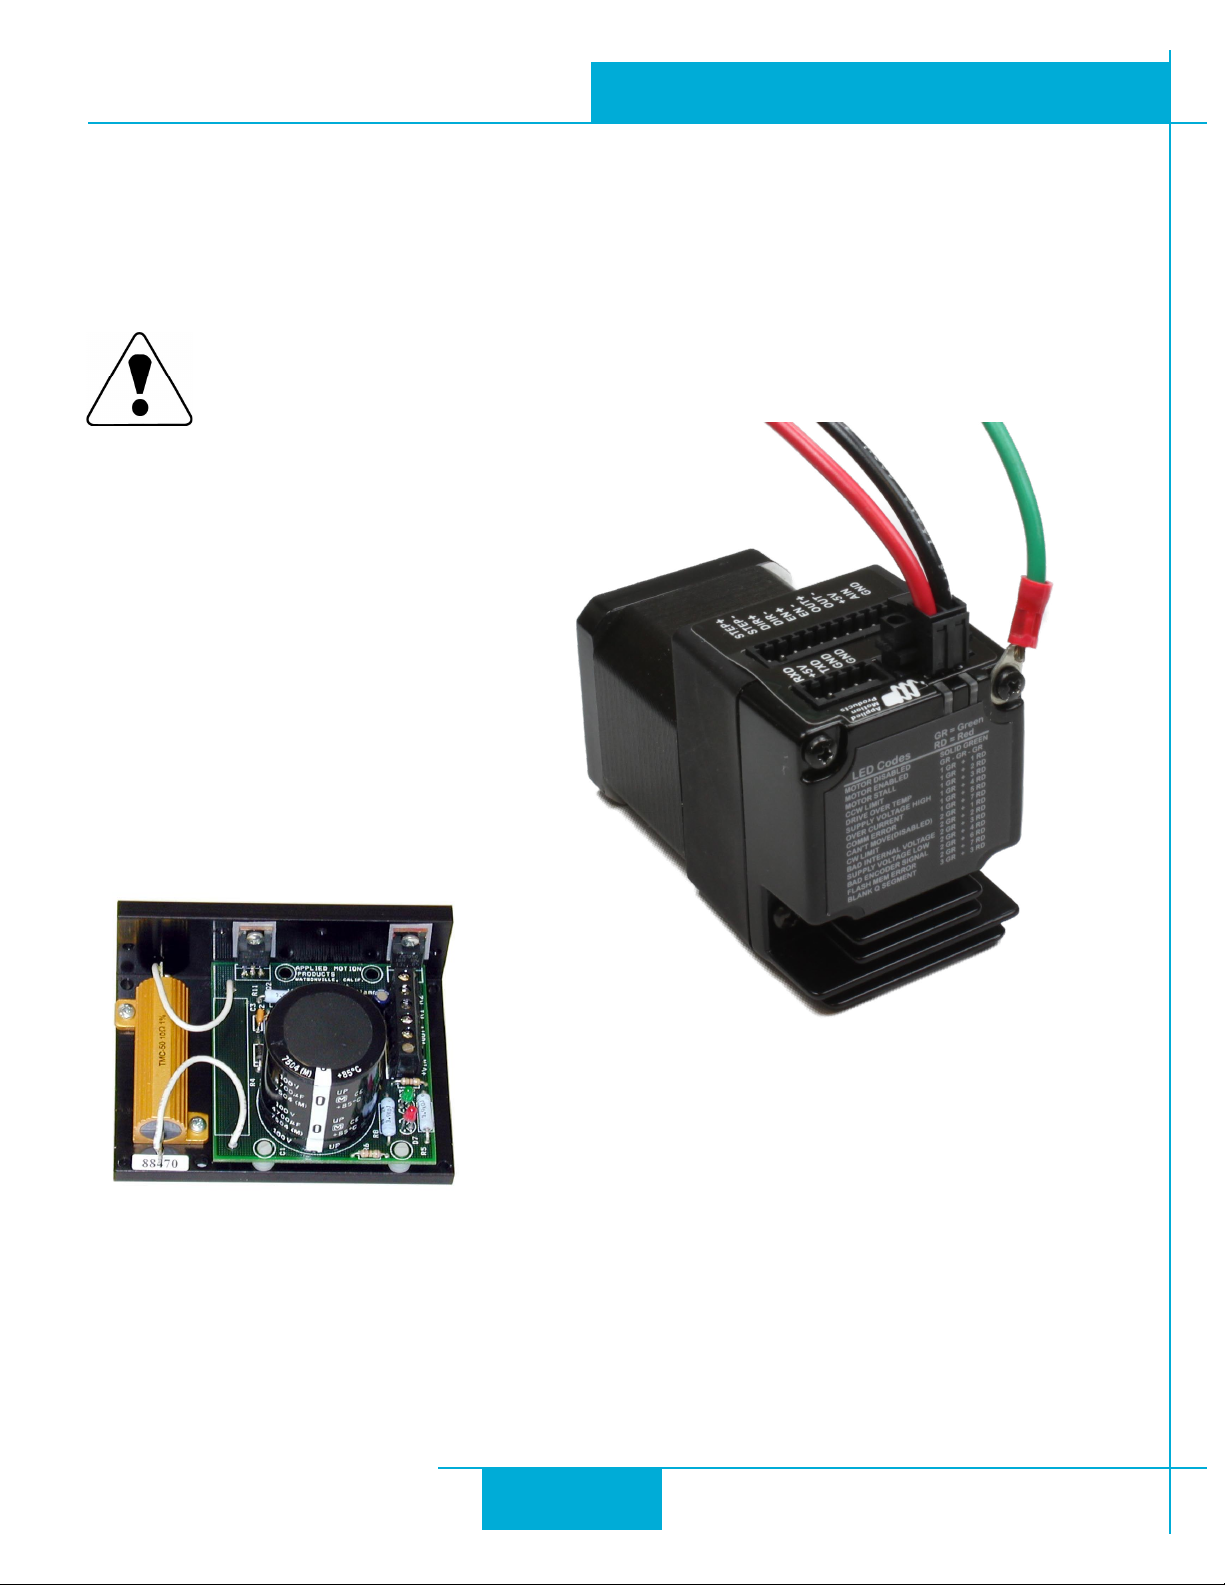
Connect the power supply “+” terminal to the drive “+” terminal and the power supply “-” terminal to the drive “-” terminal using 16 to 20-gauge wire. e STM17 contains an internal fuse connected to the “+” terminal. is fuse is not user
replaceable. If a user serviceable fuse is desired, install a 2 amp fast acting fuse in line with the “+” power supply lead.
Be careful not to reverse the wires. Reverse connection may open the internal fuse on your driver
and void your warranty.
Power Supply Connections
RC-050 Regen Clamp
If a regulated power supply is being used, there may be a problem with regeneration. When a load decelerates rapidly
from a high speed, some of the kinetic energy of the load is transferred back to the power supply, possibly tripping the
over-voltage protection of a regulated power supply, causing it to shut down. is problem can be solved with the use of
an RC-050 regeneration clamp. It is recommended that an RC-050 initially be installed in an application. If the “regen” LED
on the RC-050 never ashes, the clamp is not necessary.
12
Page 13
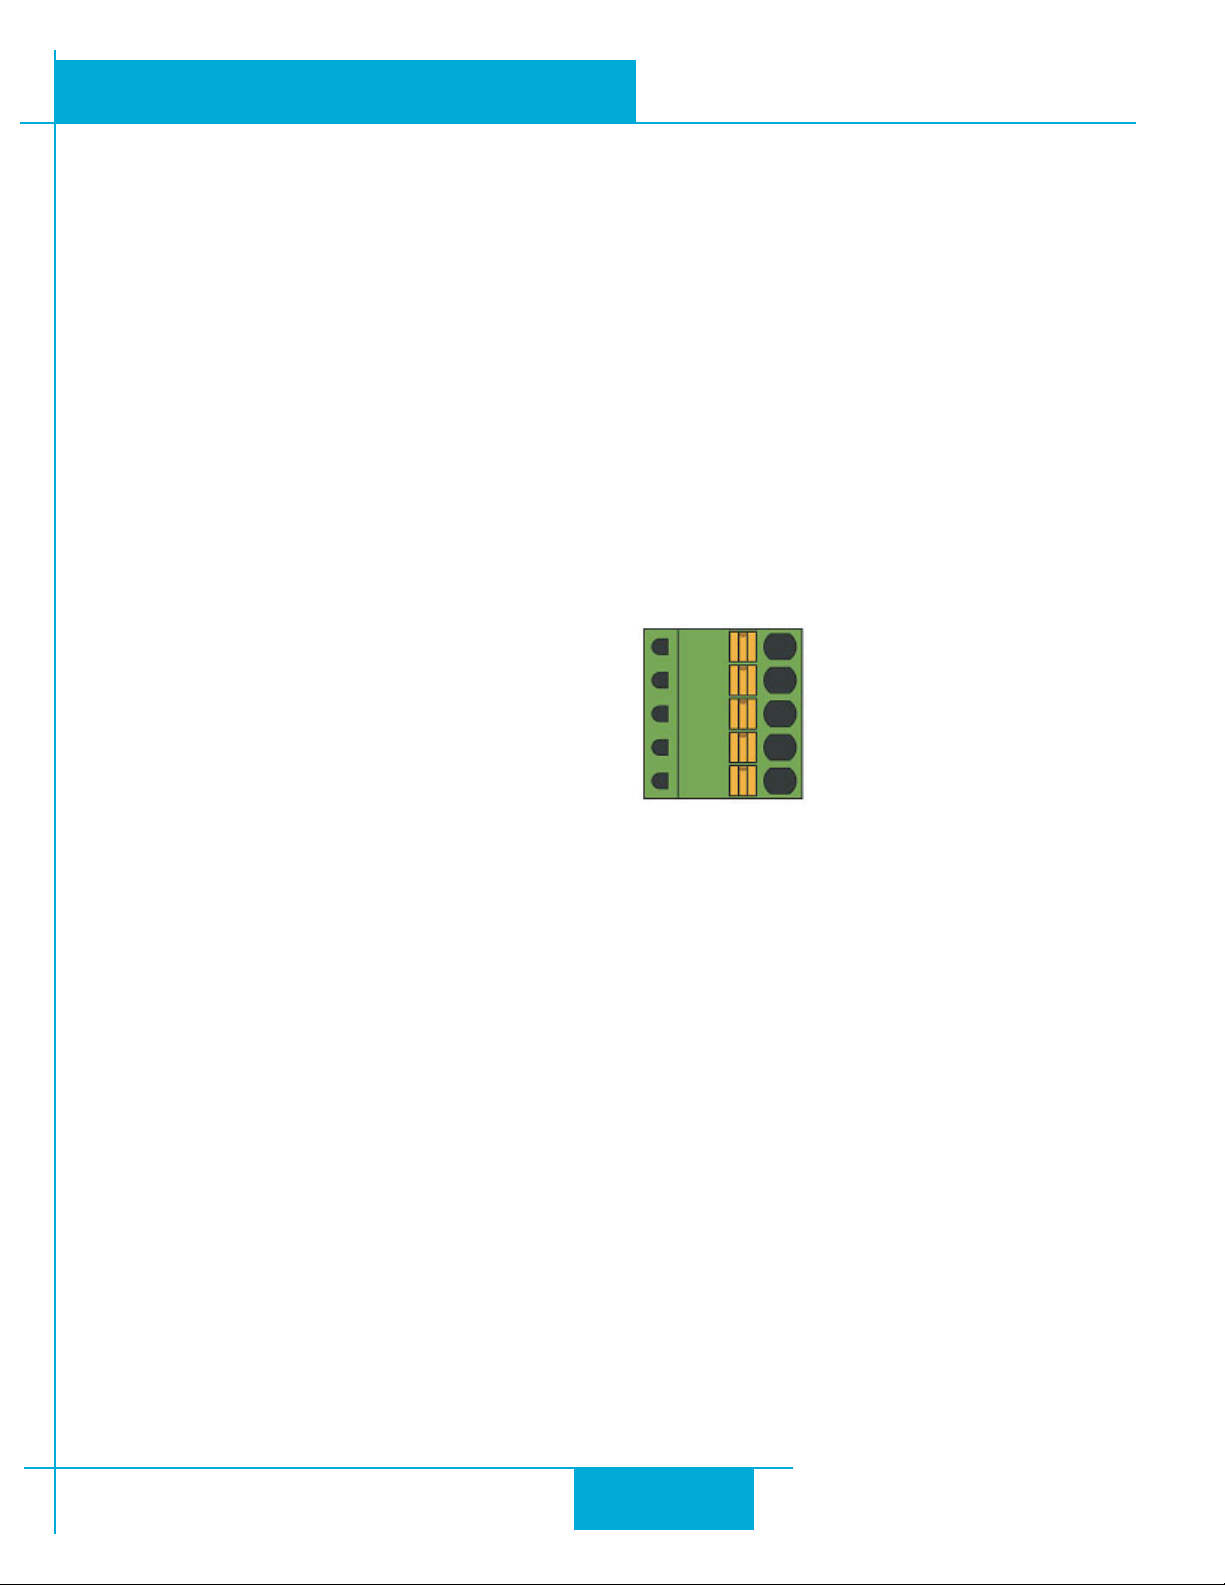
Ground (circuit ground)
Ground (circuit ground)
TX (Transmit)
+5V (Internal Jumper Select)
RX (Receive)
920-0034 rev A
STM17 Hardware Manual
9/30/2010
Connecting the STM17 Communications
e STM17 is available with two types of serial communications, RS-232 (STM17x-xAx) or RS-422/485 (STM17x-xRx).
Each type requires a dierent hardware connection for interface to a PC or other host system. e RS-232 version comes
with a cable that will provide the interface to an RS-232 port through a DB9 style connector. e RS-422/485 version
requires the user to provide both the cabling and the RS-422/485 interface. Below are descriptions of how to interface
both of these serial communication types to a PC.
Connecting to a PC using RS-232
Locate the STM17 within 8 feet (2.5 meters) of the PC. Plug the large end (DB9 connector) of the communication cable
that came with the drive into the serial port of the PC. e small end will have a 5-pin spring clamp connector. Plug this
end into the appropriate connector on the STM17. Secure the cable to the PC with the screws on the DB9 connector.
NOTE: If the PC does not have an RS-232 serial port, a USB Serial Converter will be needed. For more information,
please read
Connecting to an STM17 Using USB.
e RS-232 circuitry does not have any extra electrical “hardening” and care should be taken when connecting to the RS232 port as hot plugging could result in circuit failure. If this is a concern the RS-422/485 version should be used.
Do not plug or unplug the RS-232 connection while power is applied to the drive. is is known as “hot
plugging” and should be avoided.
Connecting to a host using RS-422/485
RS-422/485 communication allows connection of more than one drive to a single host PC, PLC, HMI or other computer.
It also allows the communication cable to be long (more than 300 meters or 1000 feet). e use of Category 5 cable is
recommended as it is widely used for computer networks, inexpensive, easily obtained and certied for quality and data
integrit y.
RS-422/485 versions of the STM17 can be used with either four-wire or two-wire congurations. Both types of congurations can be used for point-to-point (i.e. one drive and one host) or multi-drop networks (one host and up to 32
drives).
NOTE: To use the STM17 RS-422/485 version with the ST Congurator soware, the STM17 must be connected to the PC in the four-wire “point to point” conguration (see below) and congured one axis at a
time.
RS-232 Connector diagram
13
Page 14
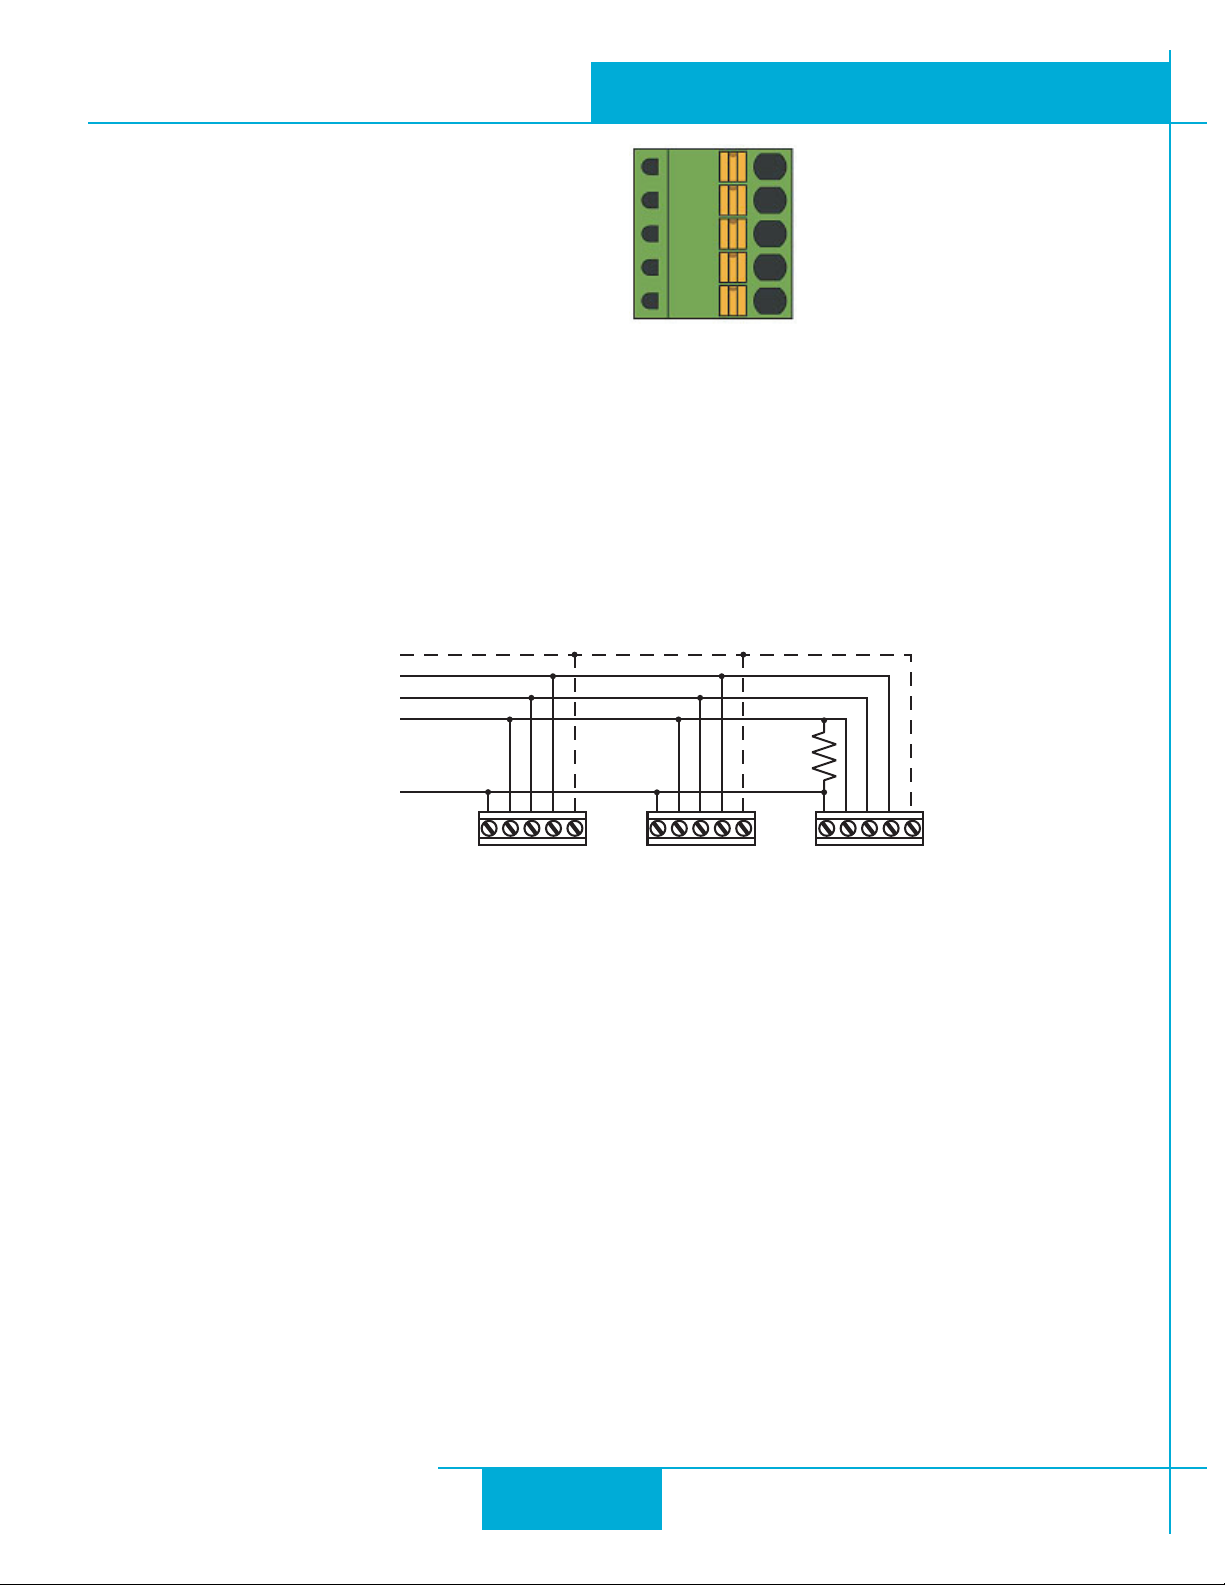
GND (circuit ground)
TX
-
TX+
RX
-
RX+
+Rx- +Tx- GND +Rx- +Tx- GND +Rx- +Tx- GND
to Host Tx+
to Host Tx-
to Host Rx+
to Host Rx-
to Host GND
Drive 1 Drive 2 Drive n
120
920-0034 rev A
9/30/2010
RS-422/485 Connector diagram
STM17 Hardware Manual
Four-Wire Conguration
Four-wire Systems utilize separate transmit and receive wires. One pair of wires must connect the host’s transmit signals to
each drive’s RX+ and RX- terminals. e other pair connects the drive’s TX+ and TX- terminals to the host’s receive signals.
A logic ground terminal is provided on each drive and can be used to keep all drives at the same ground potential.
is terminal connects internally to the DC power supply return (V-), so if all the drives on the RS-422/485 network are
powered from the same supply it is not necessary to connect the logic grounds. One drive’s GND terminal should still be
connected to the host computer ground.
NOTE: a 120 ohm terminating resistor is required at the end of a four wire network.
NOTE: If the PC does not have an RS-422/485 serial port, a converter will be required.
RS-422/485 4–wire system
14
Page 15
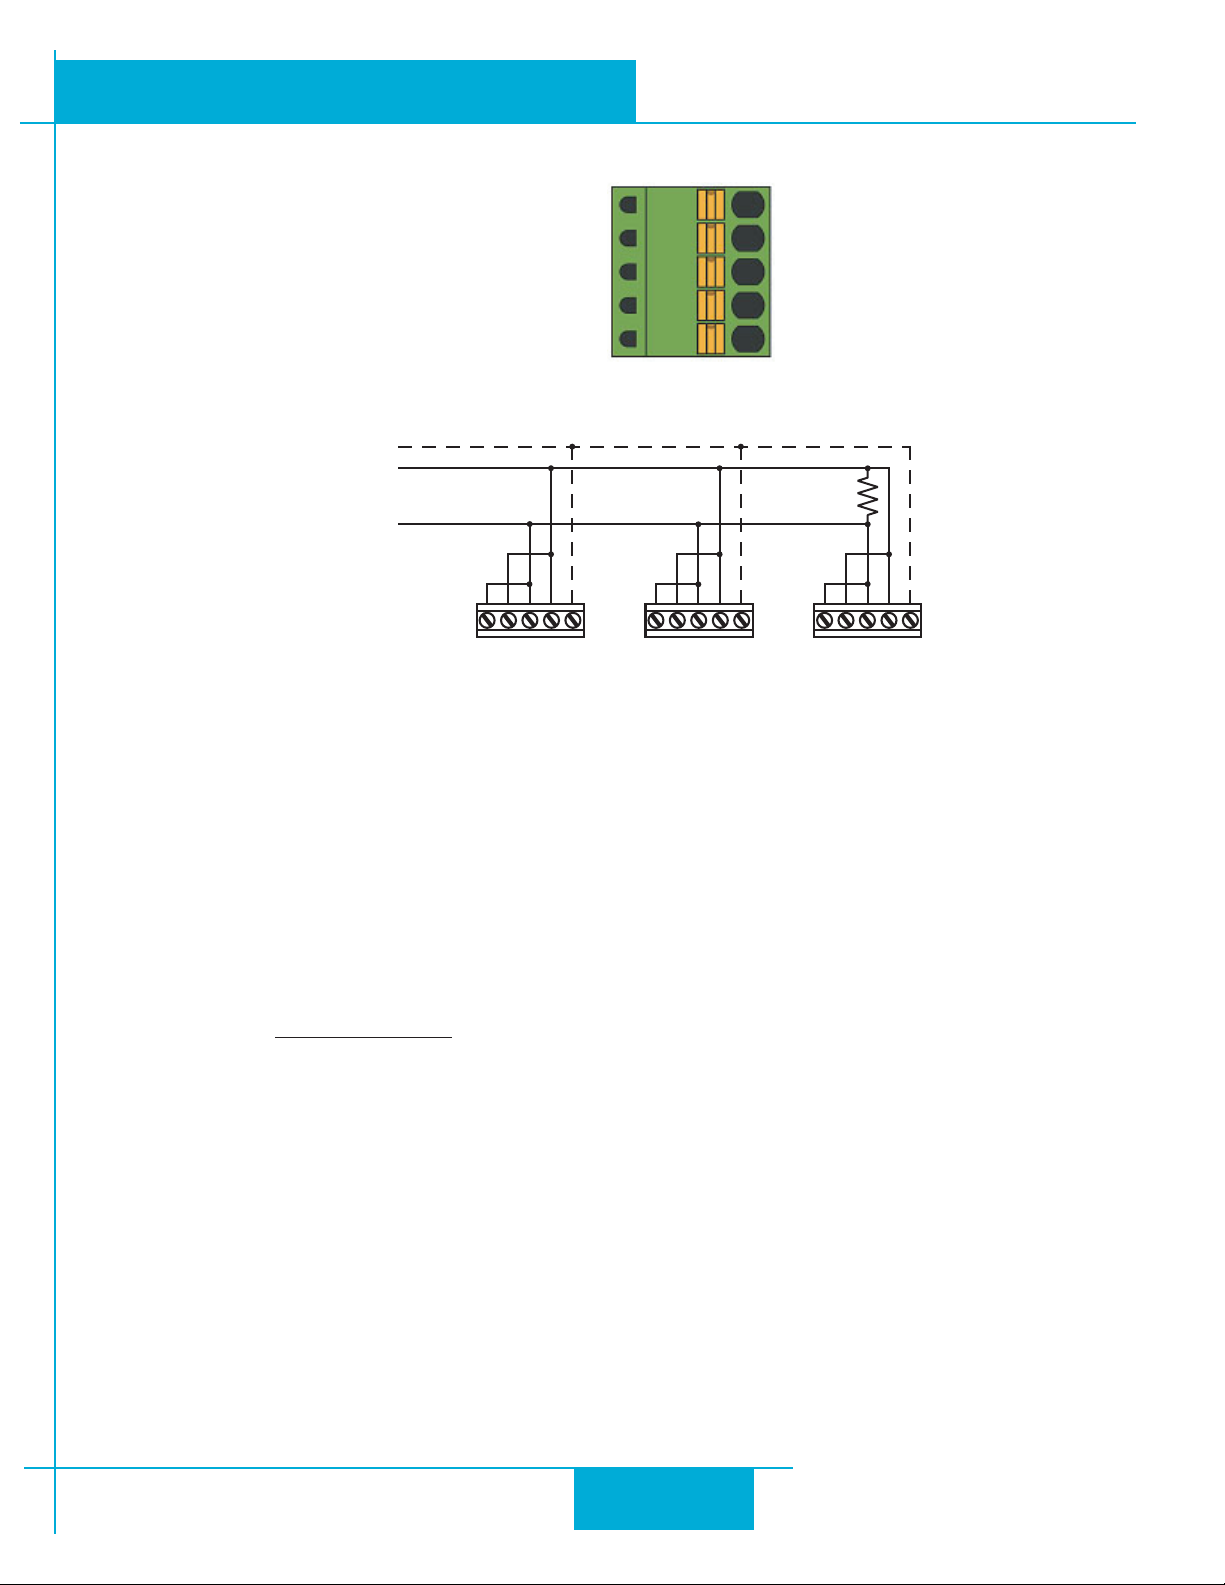
GND (circuit ground)
TX
-
TX+
RX
-
RX+
+Rx- +Tx- GND +Rx- +Tx- GND +Rx- +Tx- GND
to Host Tx+ (B)
to Host Tx- (A)
to Host GND
Drive 1 Drive 2 Drive n
120
STM17 Hardware Manual
Two-Wire Conguration
920-0034 rev A
9/30/2010
RS-422/485 Connector diagram
Typical RS-422/485 Two-Wire System
Transmit and receive on the same pair of wires can lead to trouble. e host must not only disable its transmier before
it can receive data, it must do so quickly, before a drive begins to answer a query. e STM17 includes a “transmit delay”
parameter that can be adjusted to compensate for a host that is slow to disable its transmier. is adjustment can be
made over the network using the TD command, or it can be set using the
ST Congurator
soware. It is not necessary to
set the transmit delay in a four-wire system.
NOTE: a 120 ohm terminating resistor is required at the end of the network
RS-232 to RS-485 2-wire Converter
Model 485-25E from Integrity Instruments (800-450-2001) works well for converting your PC’s RS-232 port to RS-485. It
comes with everything you need. Connect the adaptor’s “B” pin to the STM17 drive’s TX+ and RX+ terminals. Connect “A”
to the drive’s TX- and RX- terminals.
Assigning RS-485 Addresses
Before wiring the entire system, you’ll need to connect each drive individually to the host computer so that a unique address can be assigned to each drive. Use the programming cable and the
ST Congurator™
soware that came with your
drive for this purpose.
Connect the drive to your PC and then launch the
have already congured your drive, then you should click the Upload buon so that the
those of your drive. Click on the Motion buon, then select the “SCL” operating mode. If you have a Q drive, you may
want to select “Q Programming”. Either way, you’ll see the RS-485 Address panel appear. Just click on the address character of your choice. You can use the numerals 0..9 or the special characters ! “ # $ % & ‘ ( ) * + , - . / : ; < = > ? @ . Just make
ST Congurator™
soware. Finally, apply power to your drive. If you
ST Congurator™
seings match
15
Page 16
1ON2 3 4
RS-232
1ON2 3 4
2 Wire
RS-485
1ON2 3 4
4 Wire
RS-485
920-0034 rev A
9/30/2010
sure that each drive on your network has a unique address. If you are using a 2-wire network, you may need to set the
Transmit Delay, too. 10 milliseconds works on the adapters we’ve tried. Once you’ve made your choices, click Download
to save the seings to your drive.
Connecting to an STM17 using USB
e USB-COMi-M from www.byterunner.com is an excellent choice for USB to serial conversion. It can be used for all RS232, RS-422 and RS-485 applications. e USB-COM-CBL can be used for USB to RS-232 connection only.
Both adapters are available from byterunner.com. ese adapters use the FTDI chip set and are compatible with Windows XP and later, including 64 bit versions.
Note: Prolic-based USB serial adapters do not work with Vista 64 or Windows 7 64 bit operating systems.
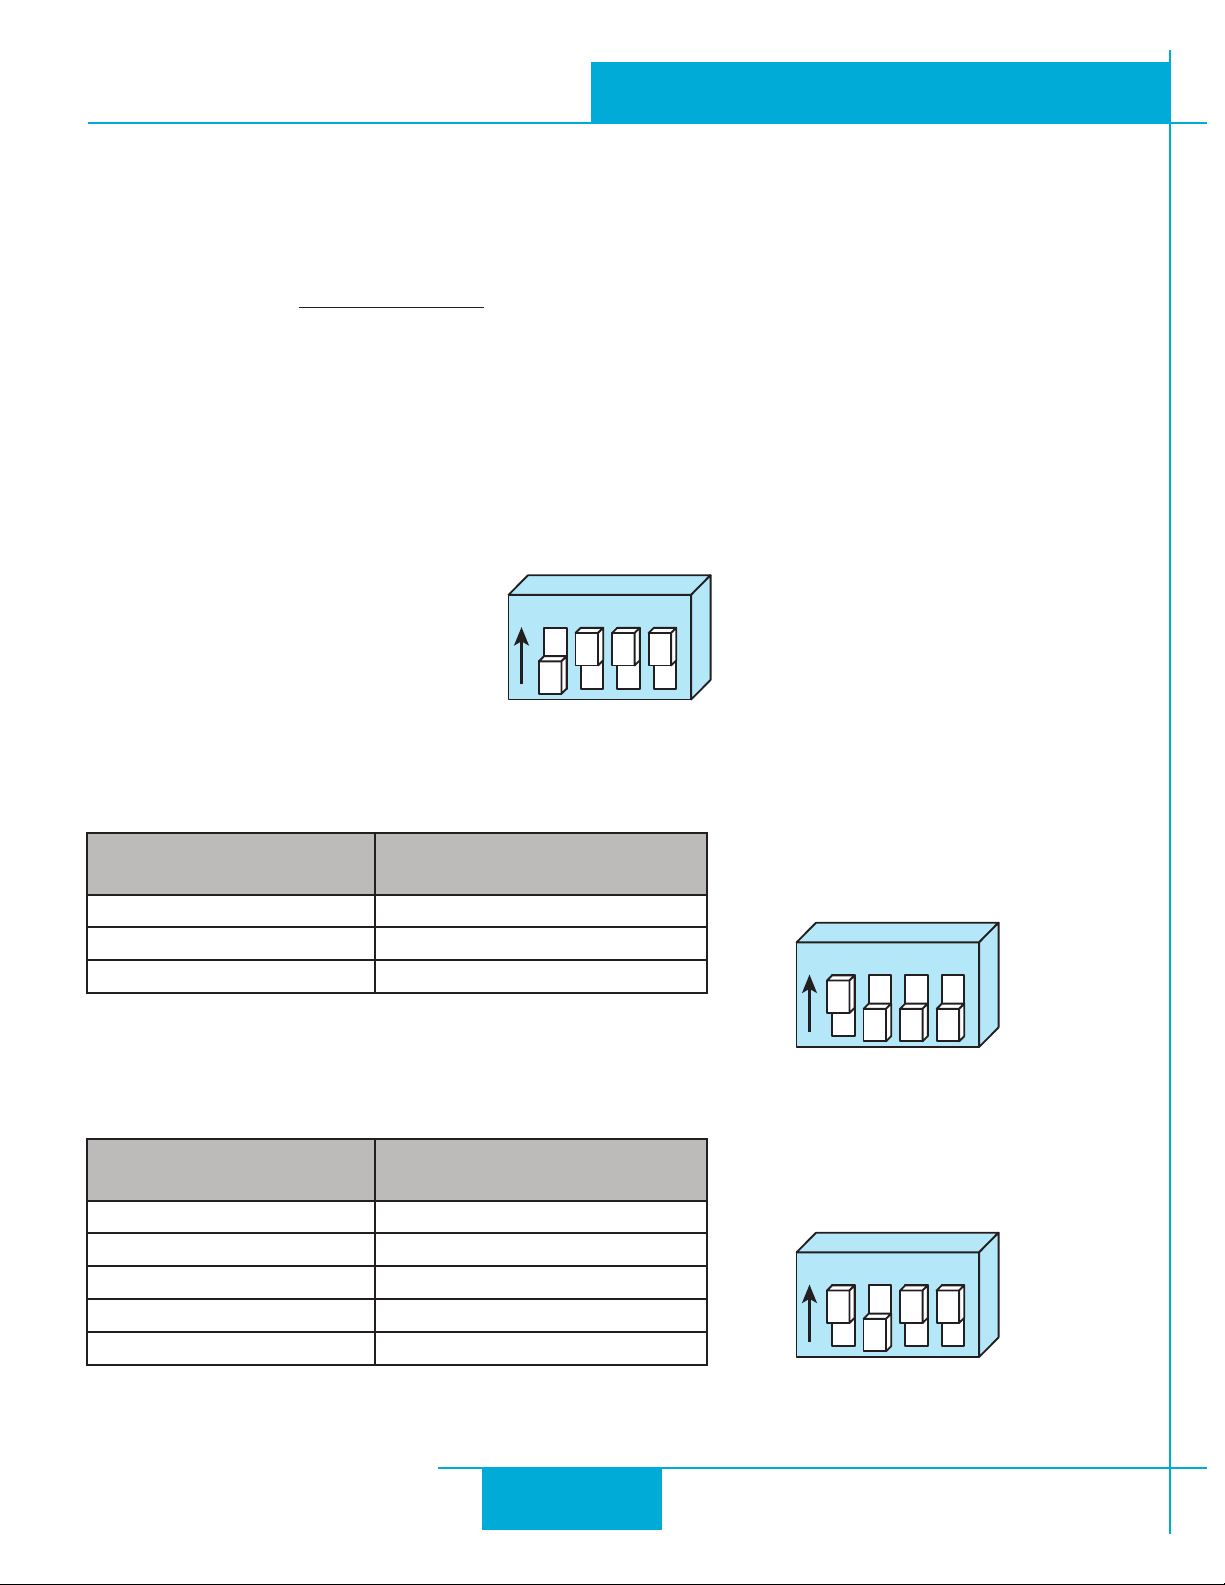
For RS-232 conversion using the USB-COMi-M, use the DB9 connector and set the switches according to the diagram
below. e DB-9 connector is not used for RS-485.
STM17 Hardware Manual
USB-COMi-M Switch Seings
For RS-485 two wire systems, set the switches and make the connections to the STM17 according the diagrams below.
USB-COMi-M 6 pin screw
terminal connector
1 RX-, TX2 RX+, TX+
6 GND
For RS-485 four wire systems, set the switches and make the connections to the STM17 according the diagrams below.
USB-COMi-M 6 pin screw
terminal connector
1 RX2 RX+
3 TX+
4 TX6 GND
STM17 5 pin connector
STM17 5 pin connector
16
Page 17
RES
inside drive
STEP+
STEP-
I/O Connector
DIR+
DIR-
EN+
EN-
OUT+
OUT-
AIN
GND
Signal
Conditioning
+5V
50ma Limit
920-0034 rev A
STM17 Hardware Manual
9/30/2010
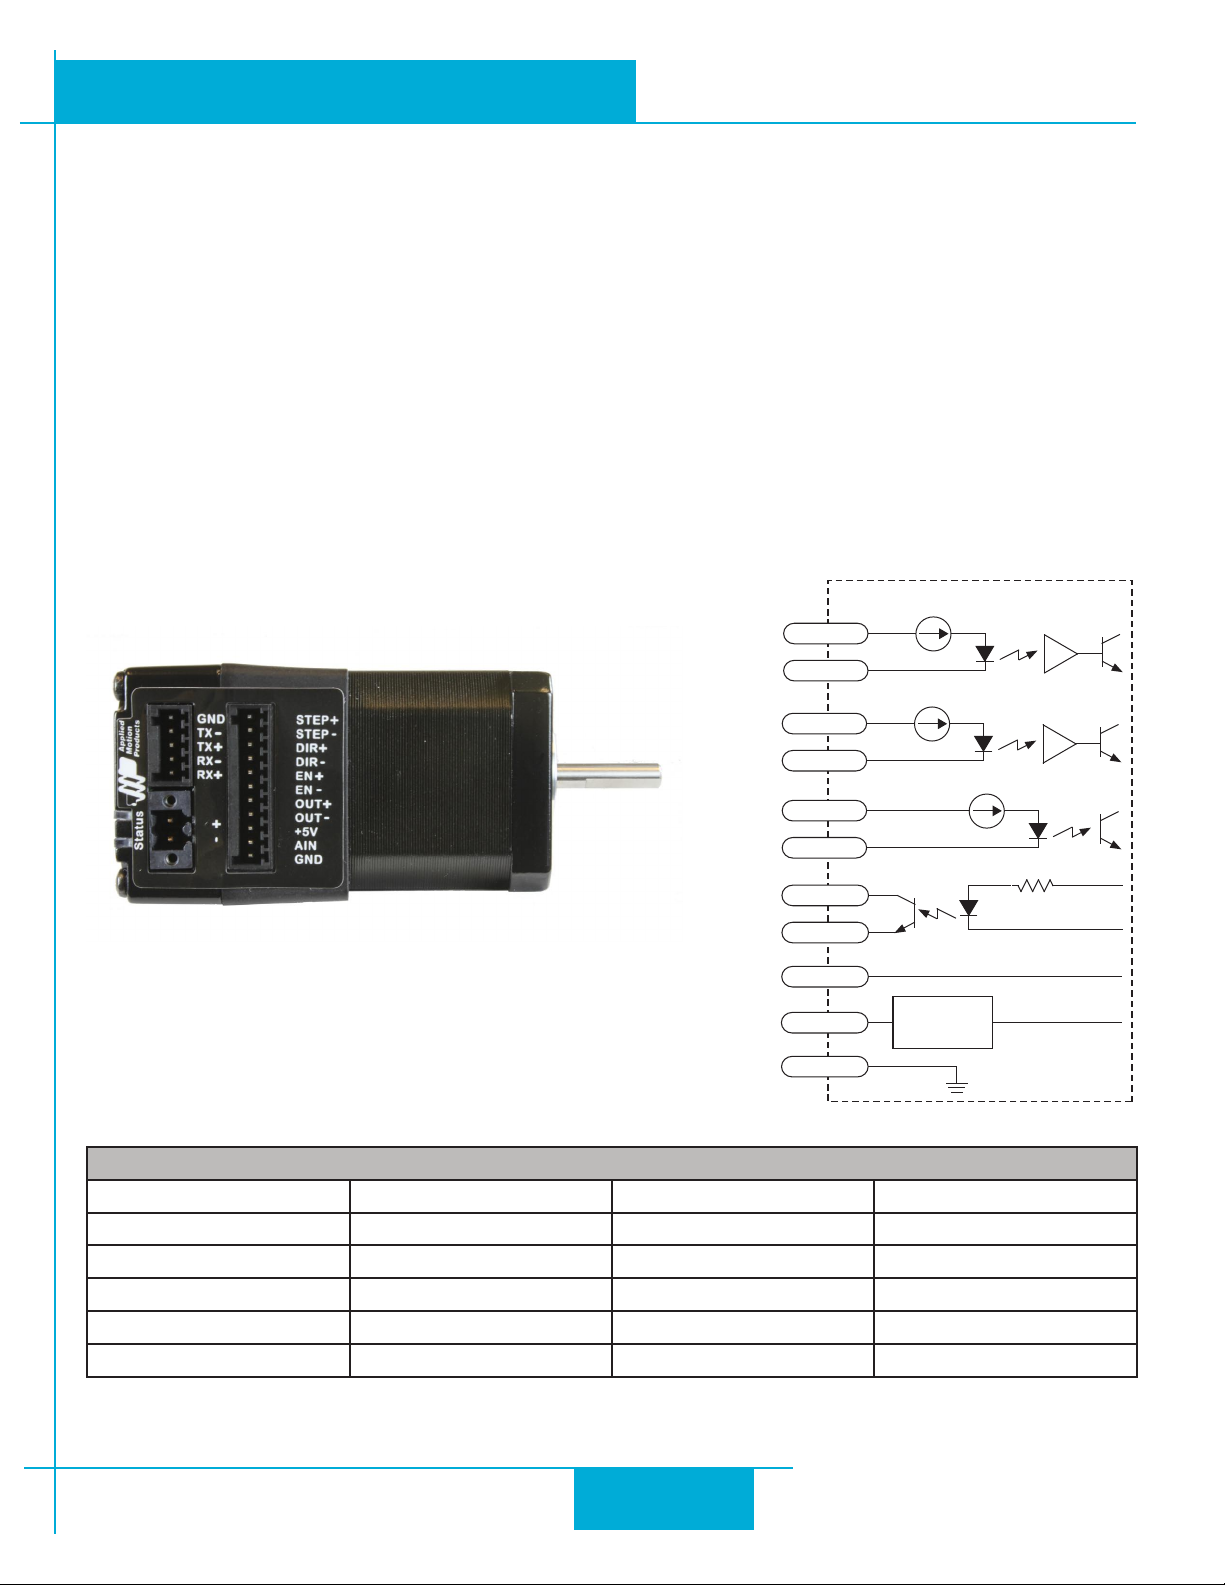
STM17 Inputs and Outputs
All STM drive+motors include three digital inputs, one analog input, and one digital output.
•STEP&DIR:5to24voltdigitalinputsignalsforcommandingposition.WhennotbeingusedfortheStep&Direction function, these inputs can be used for CW & CCW Limit, CW & CCW Jogging and Run/Stop & Direction Velocity
modes. ese inputs can also be connected to sensors, switches and other devices for use with SCL and Q commands
such as Wait Input, Seek Home, Feed to Sensor, If Input and others. Quadrature signals from encoders can also be used.
•EN:5to24voltsowareprogrammableinputcanbeusedformotorenableoralarmreset.isinputcanalsobe
connected to a sensor, switch and other devices for use with Wait Input, Seek Home, Feed to Sensor, If Input and other
commands.
•AIN:0-5Vanaloginputforvelocityorpositioncommands,withgain,ltering,osetanddead-bandseings.
•OUT:digitaloutputthatcanbesettoautomaticallycontrolamotorbrake,tosignalafaultcondition,toindicatewhen
the motor is moving or to provide an output frequency proportional to motor speed (tach signal). e output can also
be turned on and o by SCL & Q instructions like Set Output (SO).
Connector Pin Diagram
IO Functions (congure in software)
STEP (5 to 24 Volts) DIR (5 to 24 Volts) EN (5 to 24 Volts) OUT (30V, 80mA)
Step Input Dir Input Enable Input Brake Output
Jog CW Jog CCW Reset Input Alarm Output
Limit CW Limit CCW Change Speed Motion Output
Start/Stop General Purpose General Purpose Tach Output
General Purpose General Purpose
17
Page 18
STM17
DIR+
DIR DIR-
STEP+
STEP STEP-
Indexer
with
Sinking
Outputs
5-24 VDC
STM17
DIR+
DIR+
DIR- DIR-
STEP+
STEP-
STEP+
STEP-
STM17
DIR-
DIR+
STEP-
STEP+
Indexer
with
Sourcing
Outputs
STEP
5-24 VDC
DIR
920-0034 rev A
9/30/2010
STM17 Hardware Manual
e Step (STEP) and Direction (DIR) Inputs
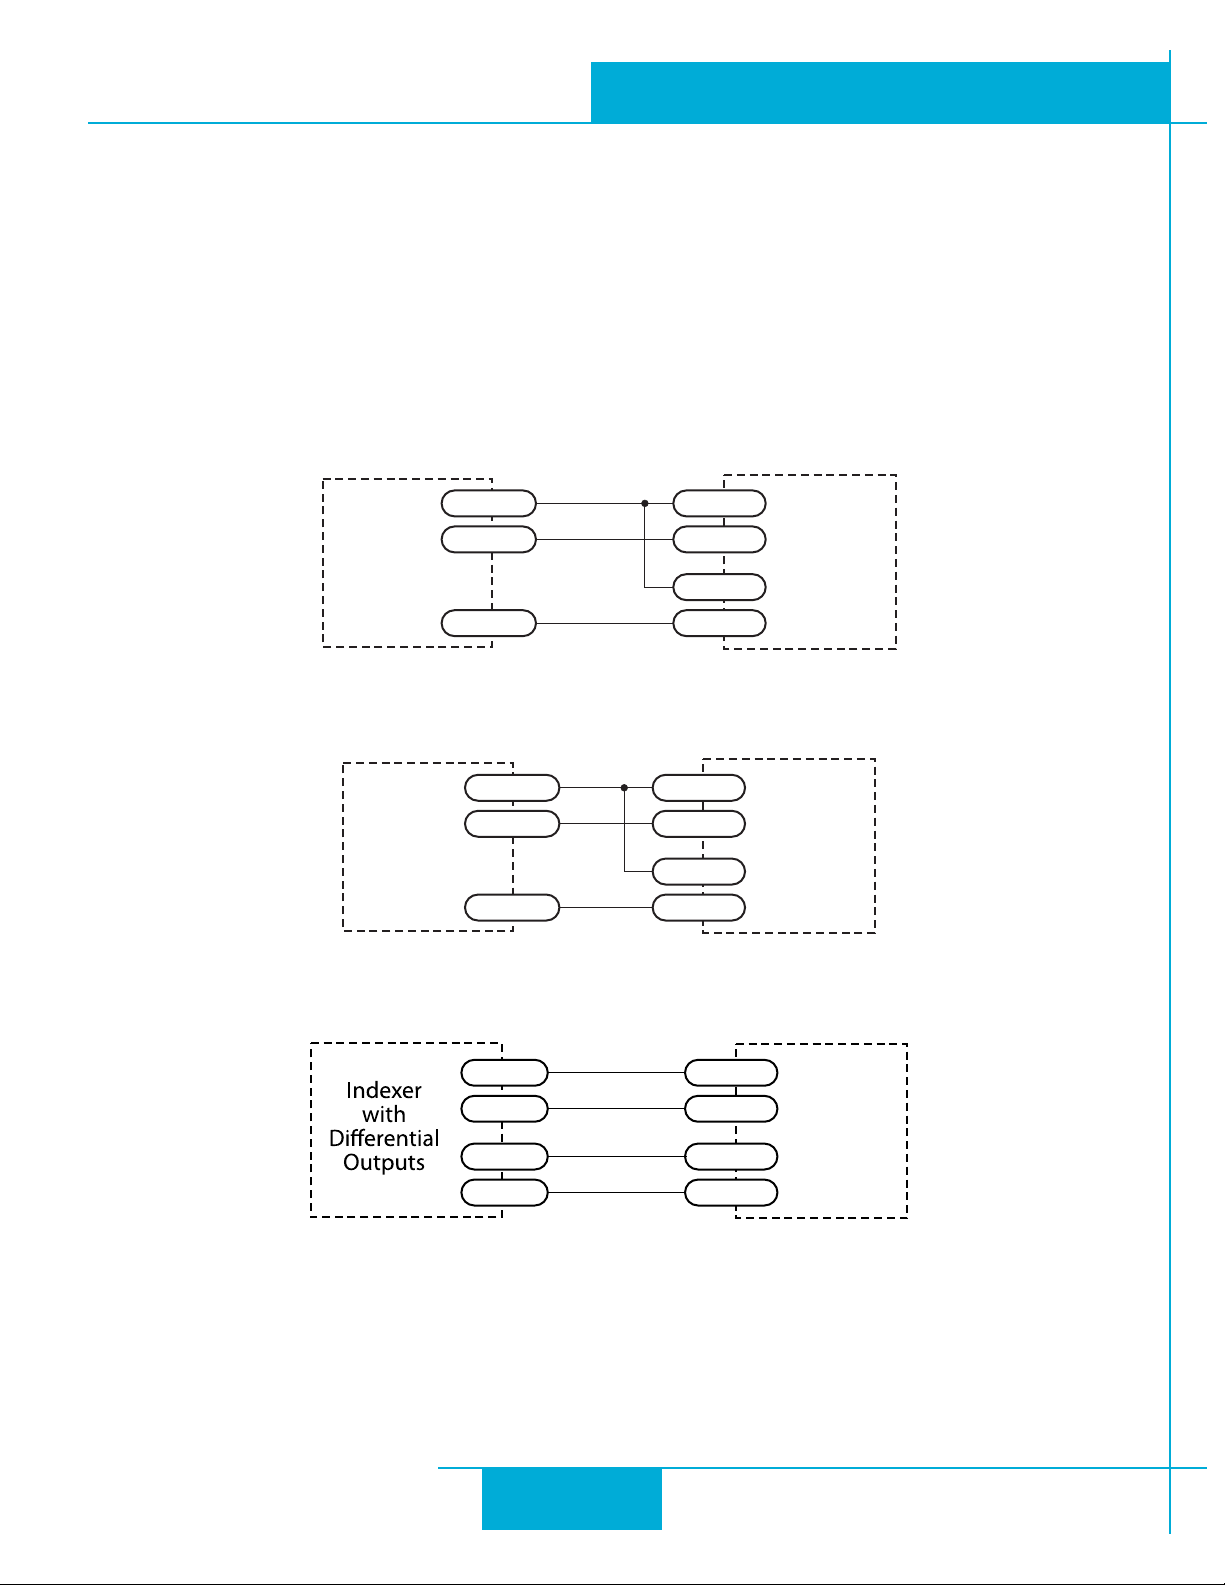
e STM17 drive+motors include two high-speed inputs called STEP and DIR. ey accept 5 to 24 volt single-ended or
dierential signals, up to 2 MHz. Typically these inputs connect to an external controller that provides step & direction
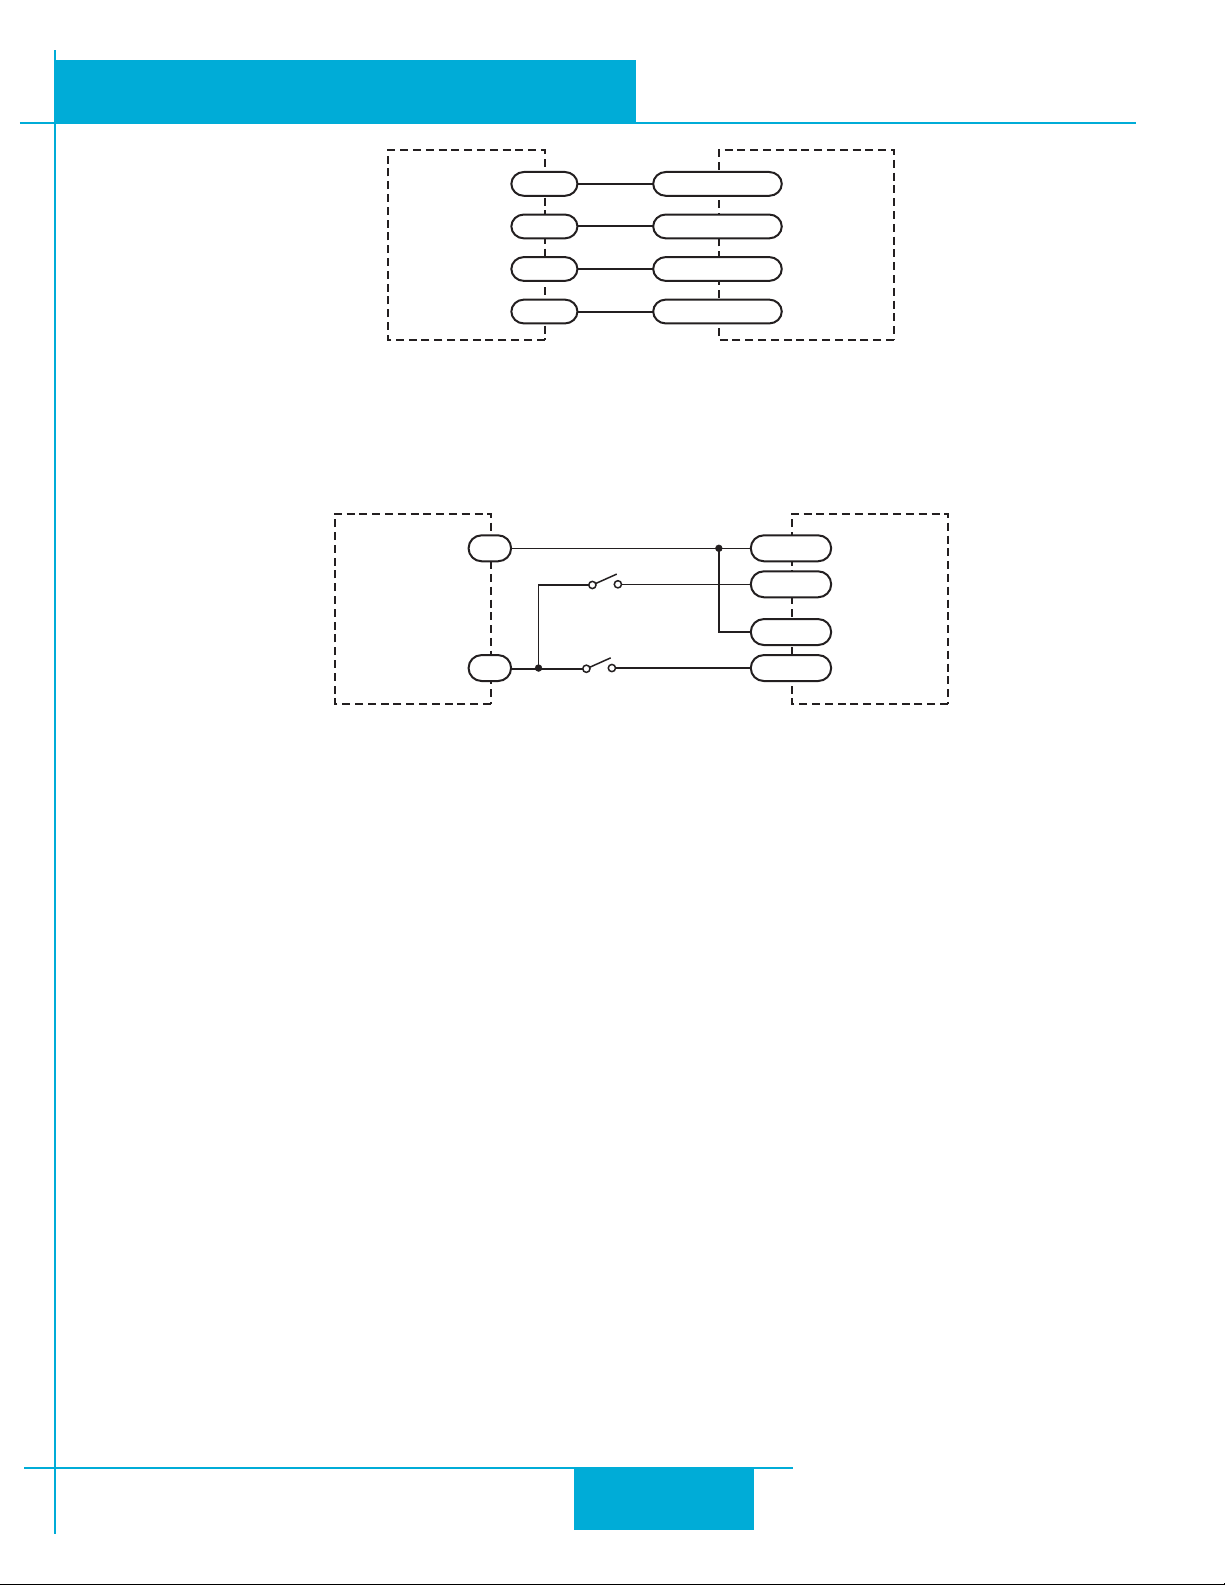
command signals. You can also connect a master encoder to the high-speed inputs for “encoder following” applications.
Or you can use these inputs with Wait Input, If Input, Feed to Sensor, Seek Home and other SCL or Q commands.
Note: If current is owing into or out of an input, the logic state of that input is low or closed. If no current is owing, or the input is not connected, the logic state is high or open.
Example connection diagrams:
Connecting to indexer with Sinking Outputs
Connecting to indexer with Sourcing Outputs
Connecting to Indexer with Dierential Outputs
(Many High Speed Indexers have Dierential Outputs)
18
Page 19
STM17
+
DIR+
DIR-
STEP+
- STEP-
5 to 24
VDC
Power
Supply
direction switch
run/stop switch
(closed=run)
STM17
Master
Encoder
DIR-
DIR+
STEP-
STEP+
B-
B+
A-
A+
STM17 Hardware Manual
Wiring for Encoder Following
920-0034 rev A
9/30/2010
Using Mechanical Switches
19
Page 20
STM17
Switch or Relay
(closed = logic Low)
EN-
EN+
5-24
VDC
Power
Supply
-
+
NPN
Proximity
Sensor
output
+
–
STM17
5-24
VDC
Power
Supply
EN-
EN+
-
+
5-24
VDC
Power
Supply
PNP
Proximity
Sensor
output
+
–
-
+
STM17
EN-
EN+
920-0034 rev A
9/30/2010
STM17 Hardware Manual
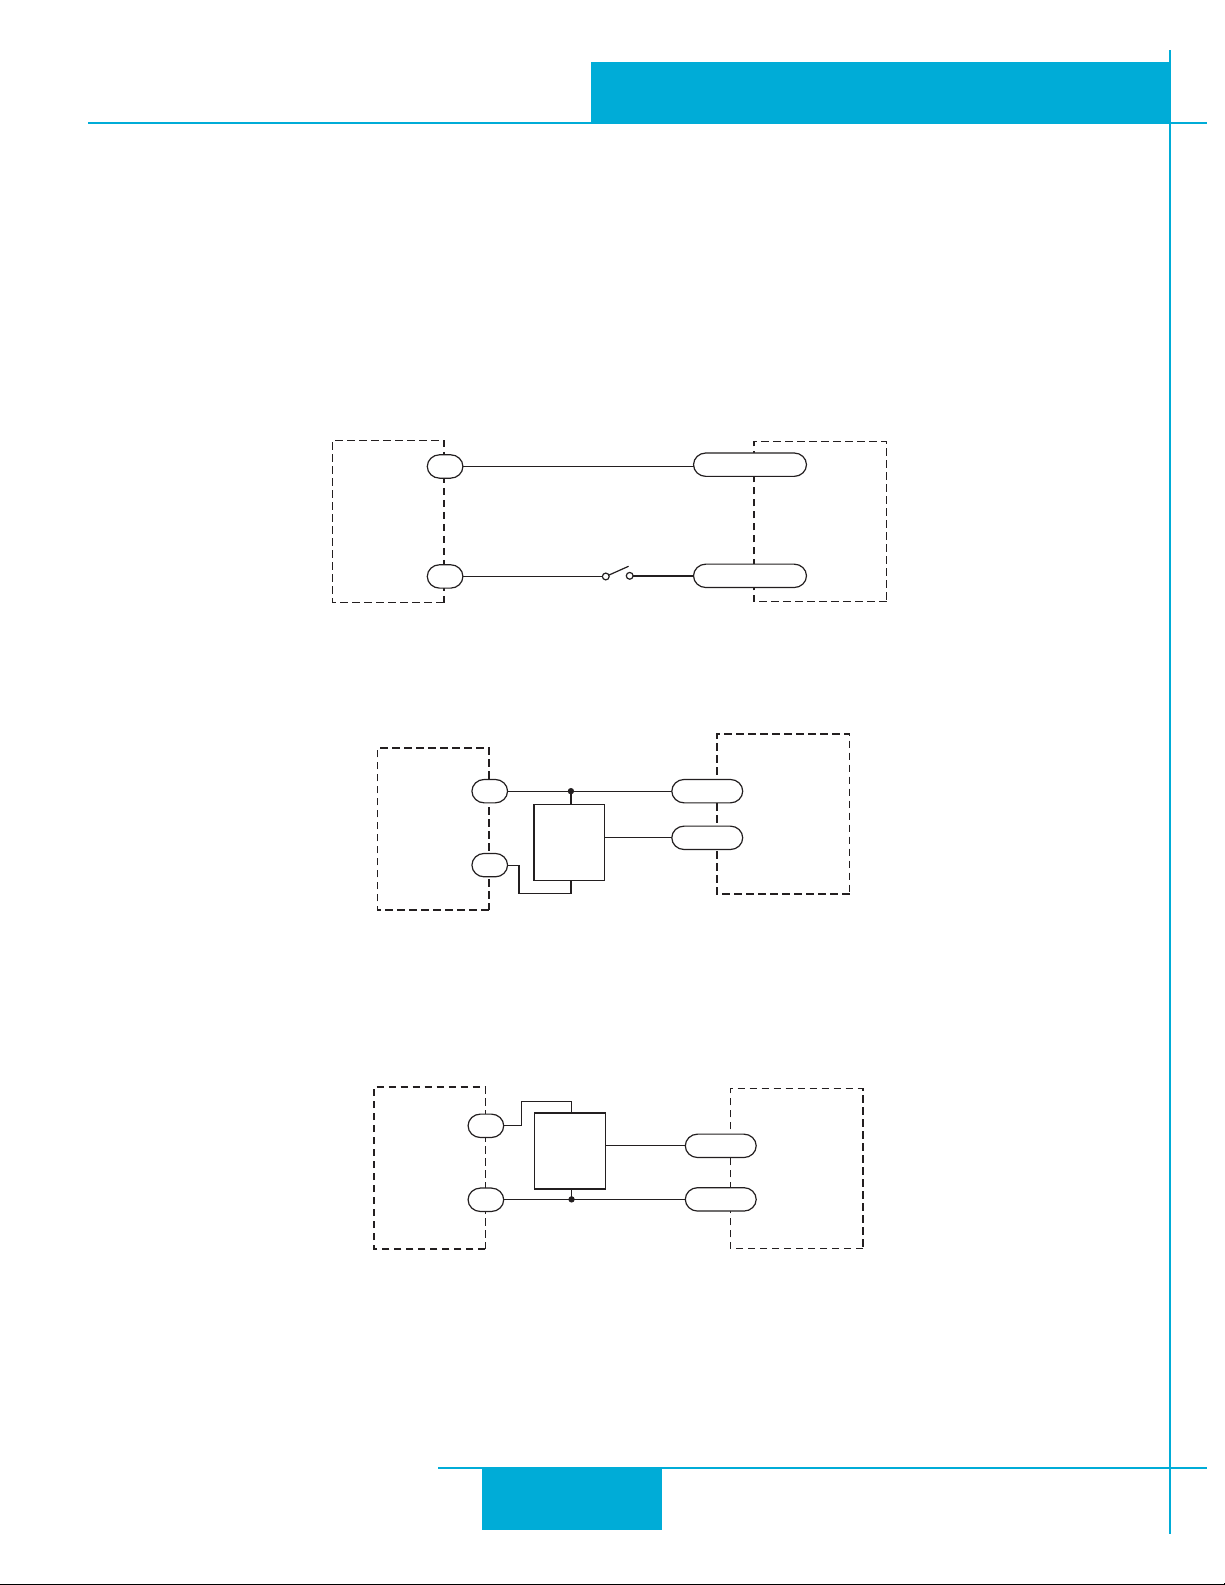
e Enable (EN) Digital Input
As mentioned in the previous section, the high-speed STEP and DIR inputs are designed for high speed operation. e Enable digital input is designed for low speed digital input operation between 5 and 24 volts DC.
Note: If current is owing into or out of an input, the logic state of that input is low or closed. If no current is
owing, or the input is not connected, the logic state is high or open.
Example connection diagrams:
Connecting the Input to a Switch or Relay
Connecting an NPN Type Proximity Sensor to an input
(When prox sensor activates, input goes low).
Connecting an PNP Type Proximity Sensor to an input
(When prox sensor activates, input goes low).
20
Page 21
inside drive
AIN
GND
Signal
Conditioning
+5V
50ma Limit
I/O Connector
1-10k
pot
c w
cc w
GND
AIN
+5V OUT
920-0034 rev A
STM17 Hardware Manual
9/30/2010
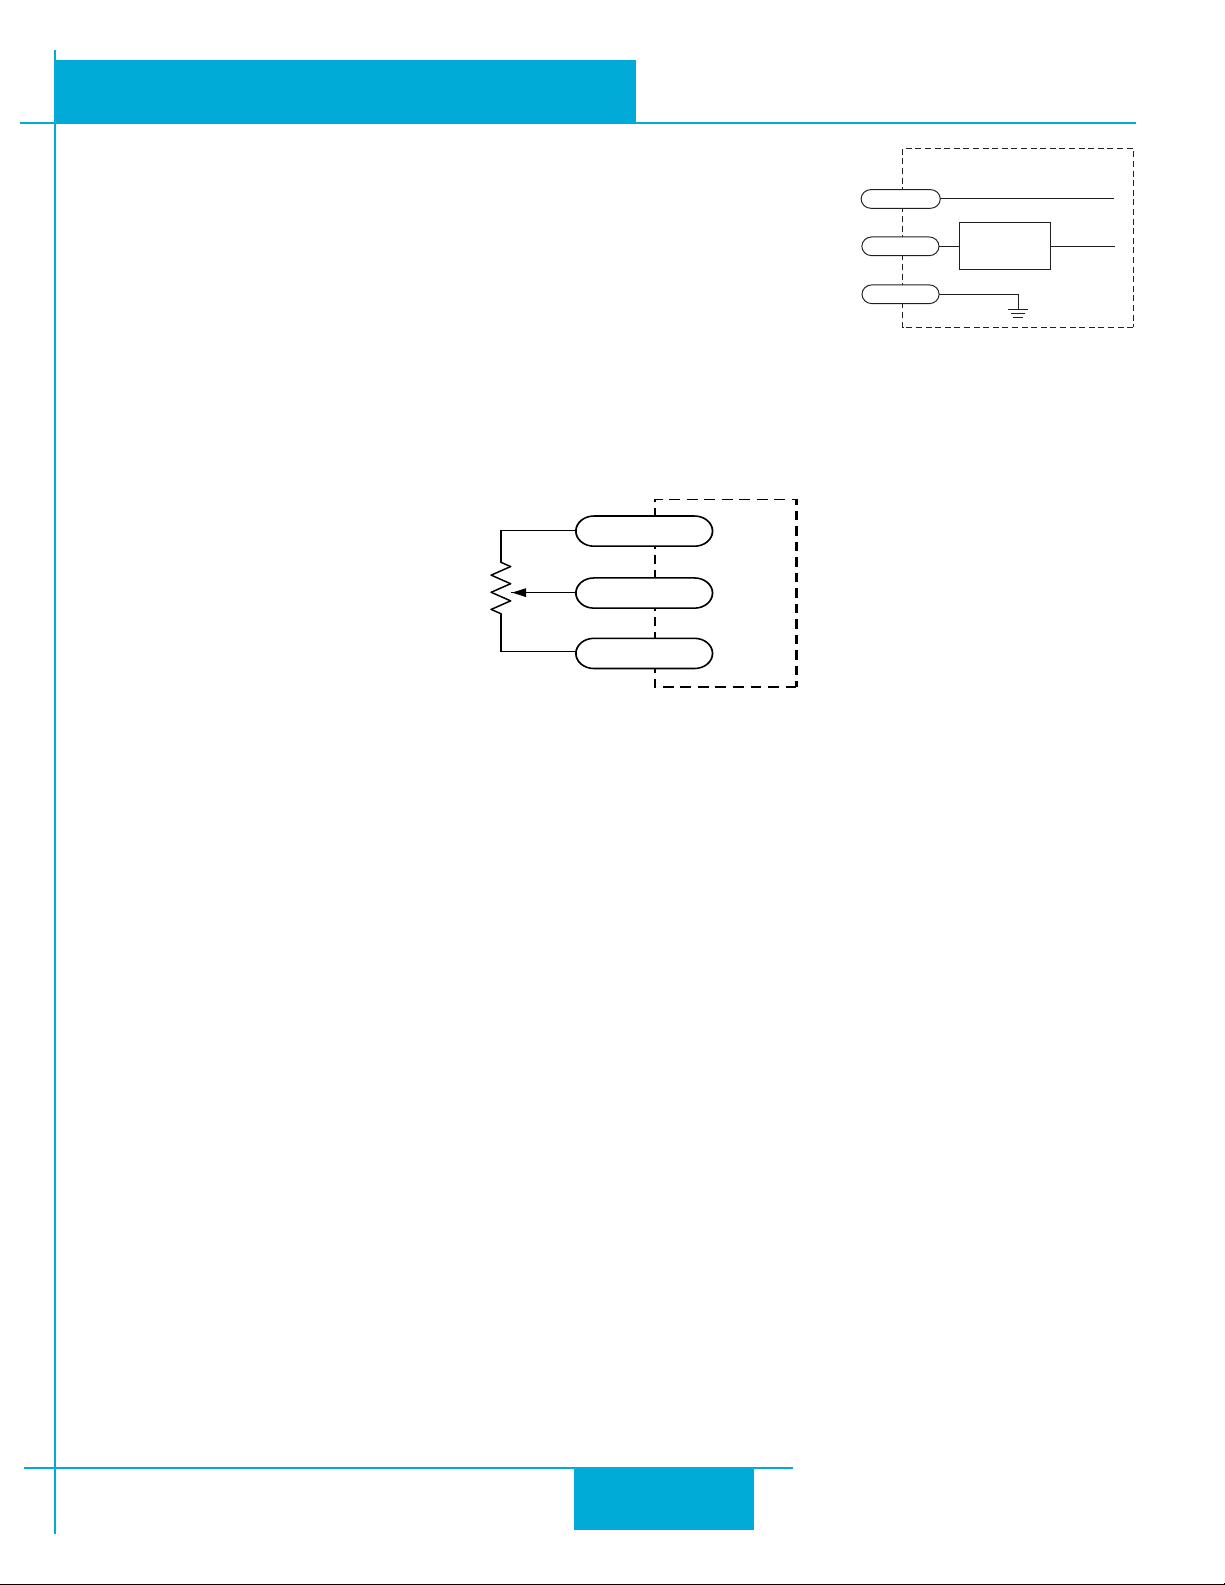
e Analog (AIN) Input
e STM17 drives feature an analog input. e input can accept a signal
range of 0 to 5 VDC. e drive can be congured to operate at a speed or
position that is proportional to the analog signal. Use the
soware to set the signal range, oset, dead-band and lter frequency. e
STM17 drives also provide a +5VDC 100ma output that can be used to
power external devices such as potentiometers. It is not the most accurate
supply for reference; for more precise readings use an external supply that can provide the desired accuracy.
Example connection diagram:
ST Congurator
Connecting a Potentiometer to the Analog Input
21
Page 22
STM17
5-24 VDC
Power Supply
+ –
Load
OUT-
OUT+
5-24 VDC
Power Supply
+ –
OUT-
OUT+
STM17
Load
STM17
1N4935 suppression diode
5-24 VDC
Power Supply
+ –
relay
OUT-
OUT+
920-0034 rev A
9/30/2010
STM17 Hardware Manual
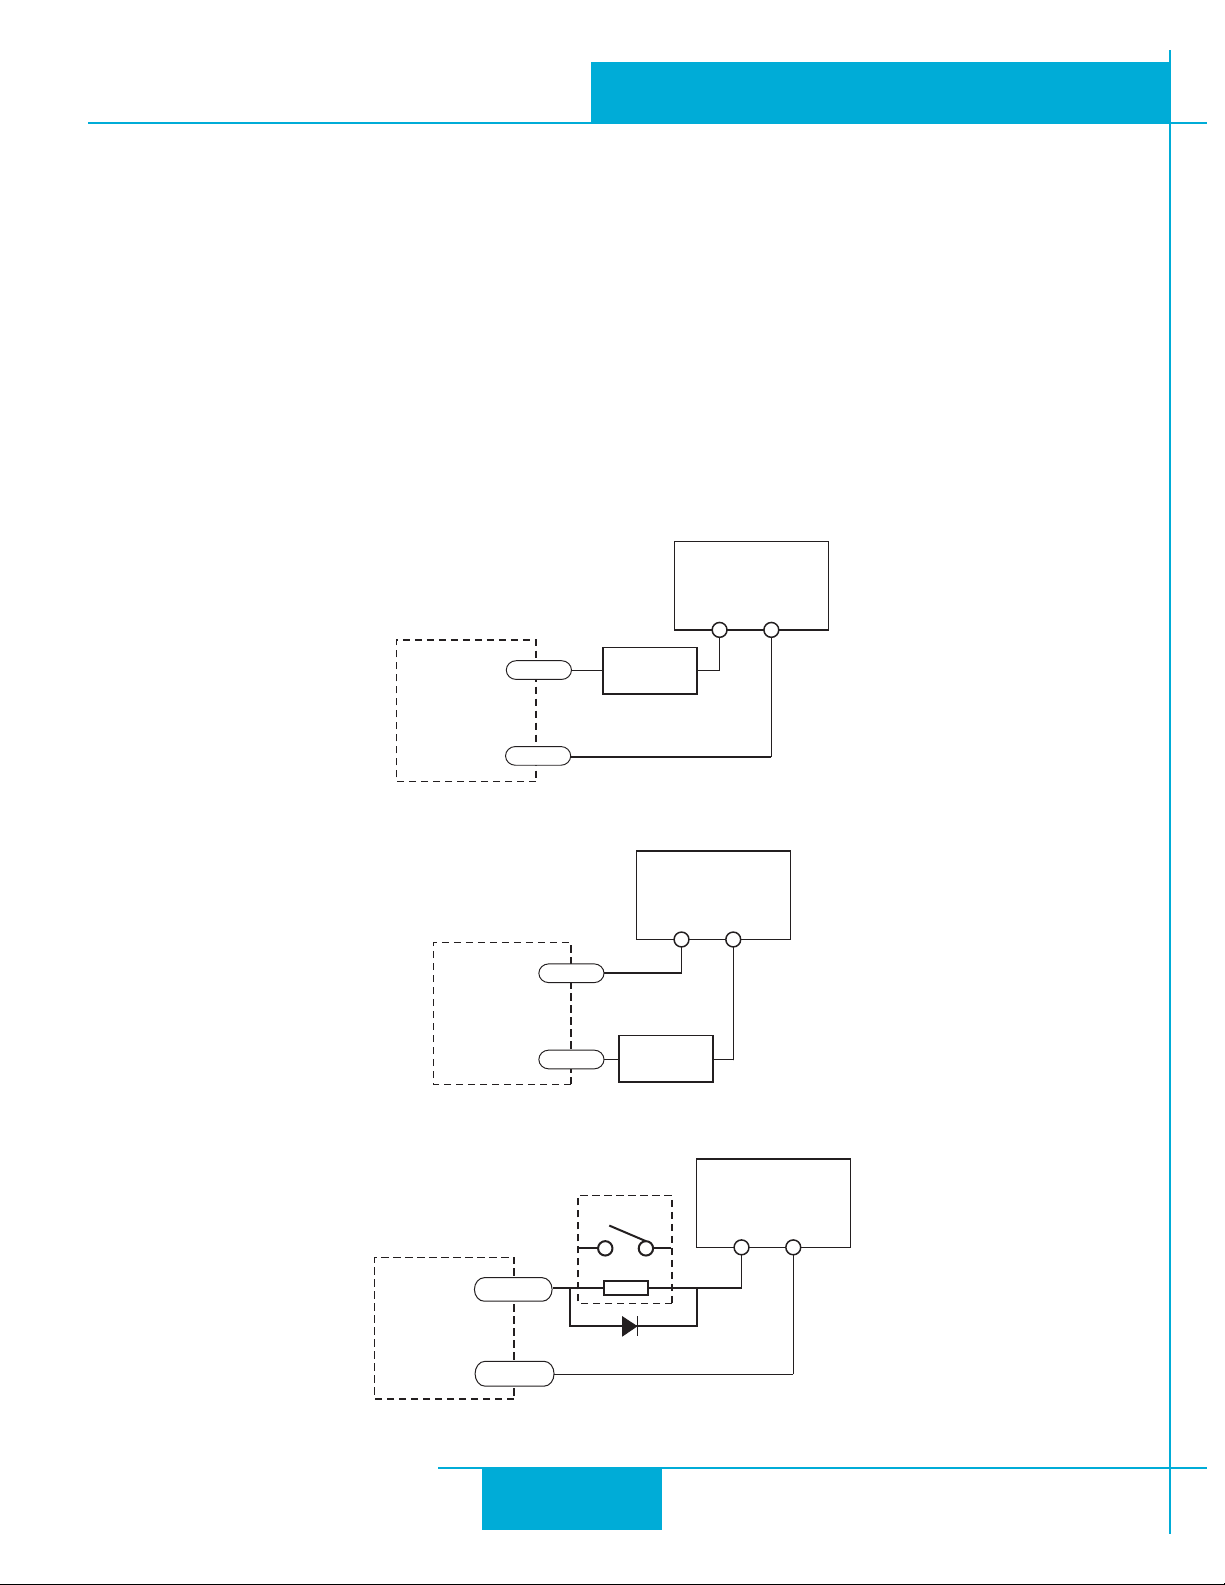
e Digital Output
e STM17 drives feature one optically isolated digital output. is output can be set to automatically control a motor brake, to signal a fault condition, to indicate when the motor is moving or to provide an output
frequency proportional to motor speed (tach signal). e output can also be turned on and o by program
instructions like Set Output. e output can be used to drive LEDs, relays and the inputs of other electronic
devices like PLCs and counters. e “OUT+” (collector) and “OUT-” (emier) terminals of the transistor are
available at the connector. is allows you to congure the output for current sourcing or sinking.
Note: If current is owing into or out of an output, the logic state of that output is low or closed. If no current is
owing, or the output is not connected, the logic state is high or open.
Do not connect the output to more than 30VDC.
e current through the output terminal must not exceed 40mA.
Example connection diagrams:
Connecting a Sinking Output
Connecting a Sourcing Output
Driving a Relay
22
Page 23
L±1
55.8
42.4
2
24
Ø 22
4.50 Flat
15
Ø 5
42.3 MAX
42.3 MAX
31
31
43.5
4-M3Depth 4.5
STM17 Hardware Manual
Reference Materials
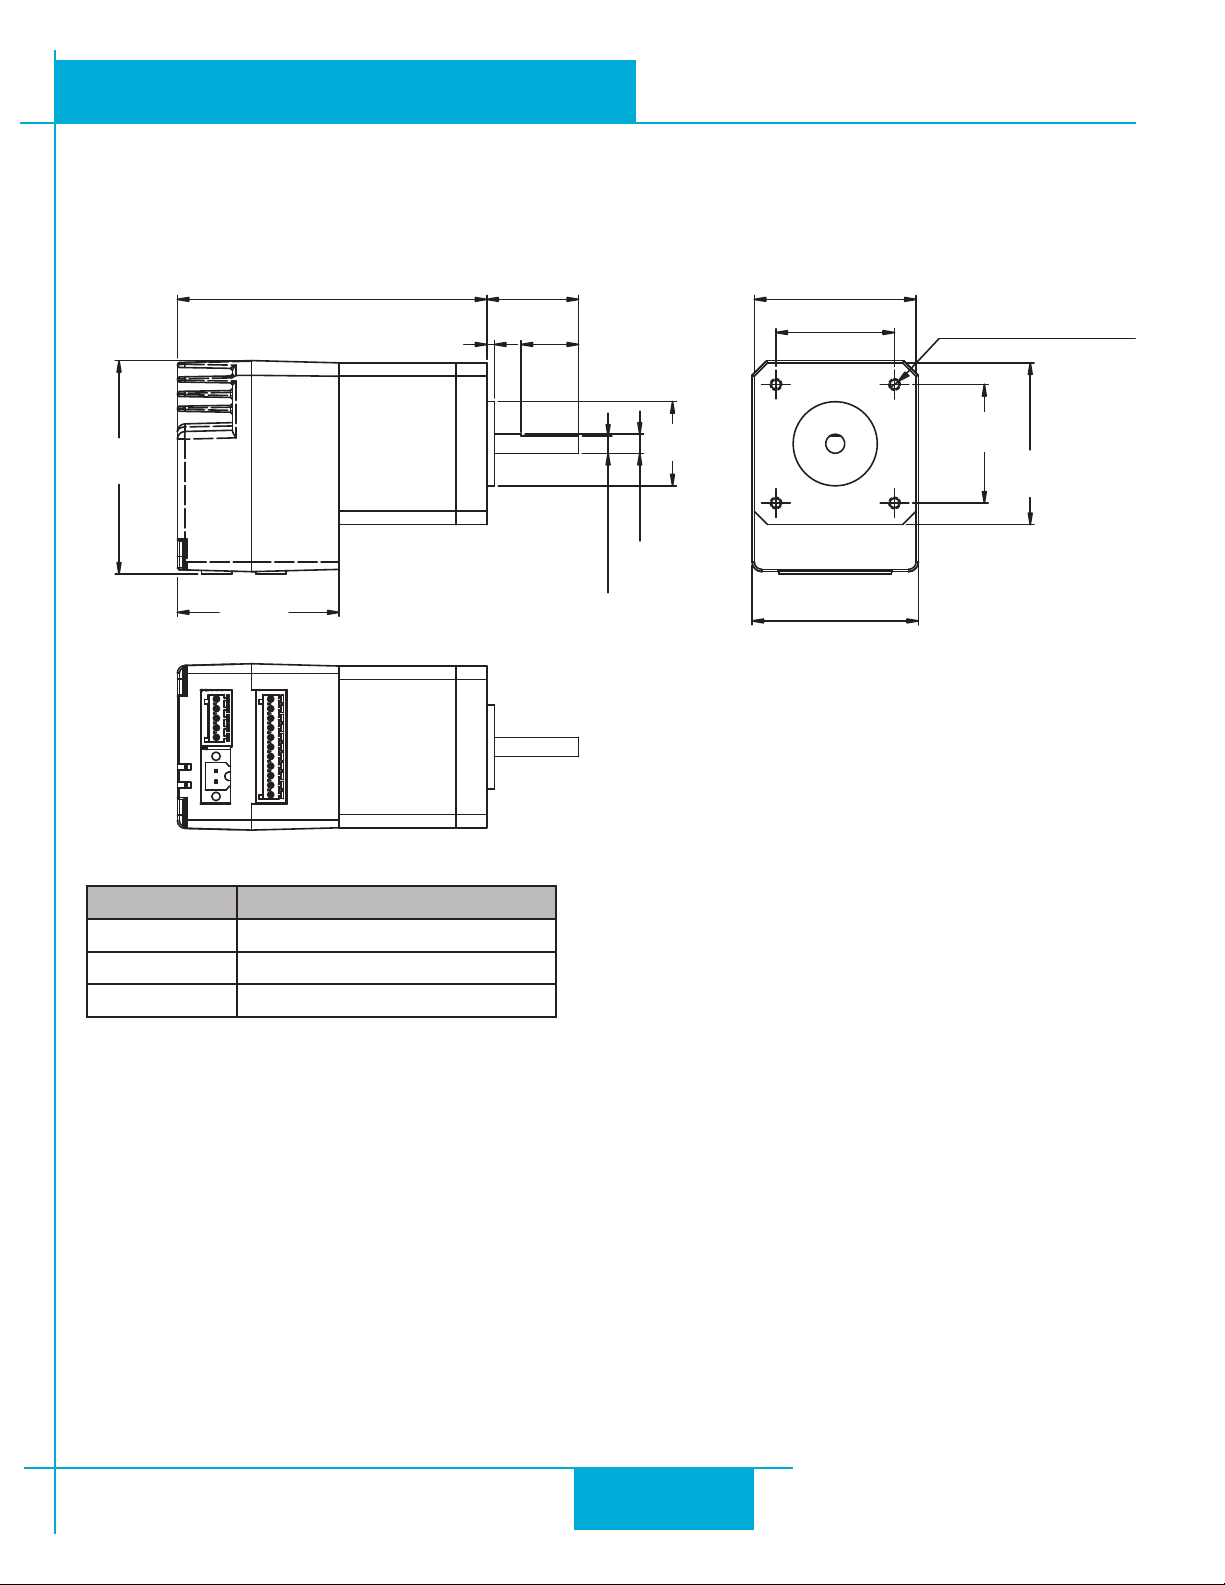
Mechanical Outlines
920-0034 rev A
9/30/2010
Model Length (L) in mm
STM17x-1 67
STM17x-2 72.5
STM17x-3 81
23
Page 24
920-0034 rev A
9/30/2010
STM17 Hardware Manual
Technical Specications
Power AmPlifier
Amplier Type Dual H-Bridge, 4 Quadrant
Current Control 4 state PWM at 16 KHz
Output Torque STM17x-1x Series – to 31 oz-in with suitable power supply
STM17x-2x Series – to 54 oz-in with suitable power supply
STM17x-3x Series – to 68 oz-in with suitable power supply
Power Supply External 12-48 volt power supply required
Input Voltage Range 10-55 volts min/max (nominal 12-48 volts), voltages outside this
range may cause driver faults and/or may damage the device
Protection Over-voltage, under-voltage, over-temp, internal motor shorts
(phase-to-phase, phase-to-ground)
Idle Current Reduction Reduction range of 0–90% of running current after a delay select-
able in milliseconds
Controller
Current Control Advanced digital current control provides excellent high speed
torque
Microstep Resolution Software selectable from 200 to 51200 steps/rev in increments of
2 steps/rev
Speed Range Speeds up to 80 rps
Distance Range Over 10,000,000 revolutions (at 200 steps/rev)
Anti Resonance (Electronic
Damping)
Auto Setup Measures motor parameters and congures motor current control
Self Test Checks internal and external power supply voltages, diagnoses
Microstep Emulation Performs high resolution stepping by synthesizing coarse steps into
Dynamic Smoothing Software congurable ltering for use in removing spectral compo-
Dynamic Current Control Software congurable for running current, accel current, idle cur-
Raises the system-damping ratio to eliminate midrange instability
and allow stable operation throughout the speed range of the mo-
tor
and anti-resonance gain settings
open motor phases
ne microsteps
nents from the command sequence, reduces jerk, limiting excita-
tion of system resonance
rent, to make motion smoother and the motor run cooler
24
Page 25
920-0034 rev A
STM17 Hardware Manual
Multiple Modes Of Control Pulse Input - Step & Direction, CW/CCW, A/B Quadrature (incre-
mental encoder
Velocity - Analog Velocity, Switch Control Velocity, Serial Command-
ed Velocity
Serial Command Language (SCL)
Stored Program Execution (Q models only)
Noise Filtering Programmable hardware digital noise lter, software noise lter
Encoder Feedback Optional 4000 counts/rev encoder feedback
Non-Volatile Storage Congurations are saved in FLASH memory on-board the DSP
inPuts And outPuts
Step Input STEP +/-
Inputs: optically isolated, 5-24 volts, minimum pulse width 250 ns.,
maximum pulse frequency 3 MHz. Max current draw 12mA.
Functions: Step, CW Step, A Quadrature, CW Limit, CW Jog, general
purpose input; adjustable bandwidth digital noise rejection lter
Direction Input DIR+/-
Inputs: optically isolated, 5-24 volts, minimum pulse width 250 ns.,
maximum pulse frequency 3 MHz. Max current draw 12mA.
Functions: DIR, CCW Step, B Quadrature, CCW Limit, CCW Jog,
general purpose input; adjustable bandwidth digital noise rejection
lter
Enable Input EN+/-
Inputs: optically isolated, 5-24 volts, minimum pulse width 100 us.,
maximum pulse frequency 10 KHz. Max current draw 12mA.
Functions: Enable, alarm reset, speed control, general purpose
input; adjustable bandwidth digital noise rejection lter
Output OUT+/-
Open Collector, 30 volts, 100 mA max, maximum pulse frequency
10 KHz
Functions: Fault, brake, motion, tach, and general purpose pro-
grammable
Analog Input AIN
Input: 0-5 volts (AIN referenced to GND). Input impedance: 30k
ohms min.
Functions: analog control modes and general purpose analog us-
age; programmable for signal range, offset, dead band and ltering
Analog Input Resolution 12 bits
Communication Interface RS-232 or RS-422/485
Supply Output +4.8-5 volts @ 100mA maximum
9/30/2010
25
Page 26
35
STM17X
-
1
12V
24V
48V
25
30
15
20
oz-in
10
0
5
0 10 20 30 40 50
rps
920-0034 rev A
9/30/2010
STM17 Hardware Manual
PHYsiCAl & enVironmentAl
Mass STM17x-1xx: 292 g (10.3 oz)
STM17x-2xx: 360 g (12.7 oz)
STM17x-3xx: 441 g (15.6 oz)
Rotor Inertia STM17x-1xx: 38 g-cm2 (0.21 oz-in2)
STM17x-2xx: 57 g-cm2 (0.31 oz-in2)
STM17x-3xx: 82 g-cm2 (0.45 oz-in2)
Ambient Temperature 0-40°C (32-104°F) when mounted to a suitable heatsink
Humidity 90% non-condensing
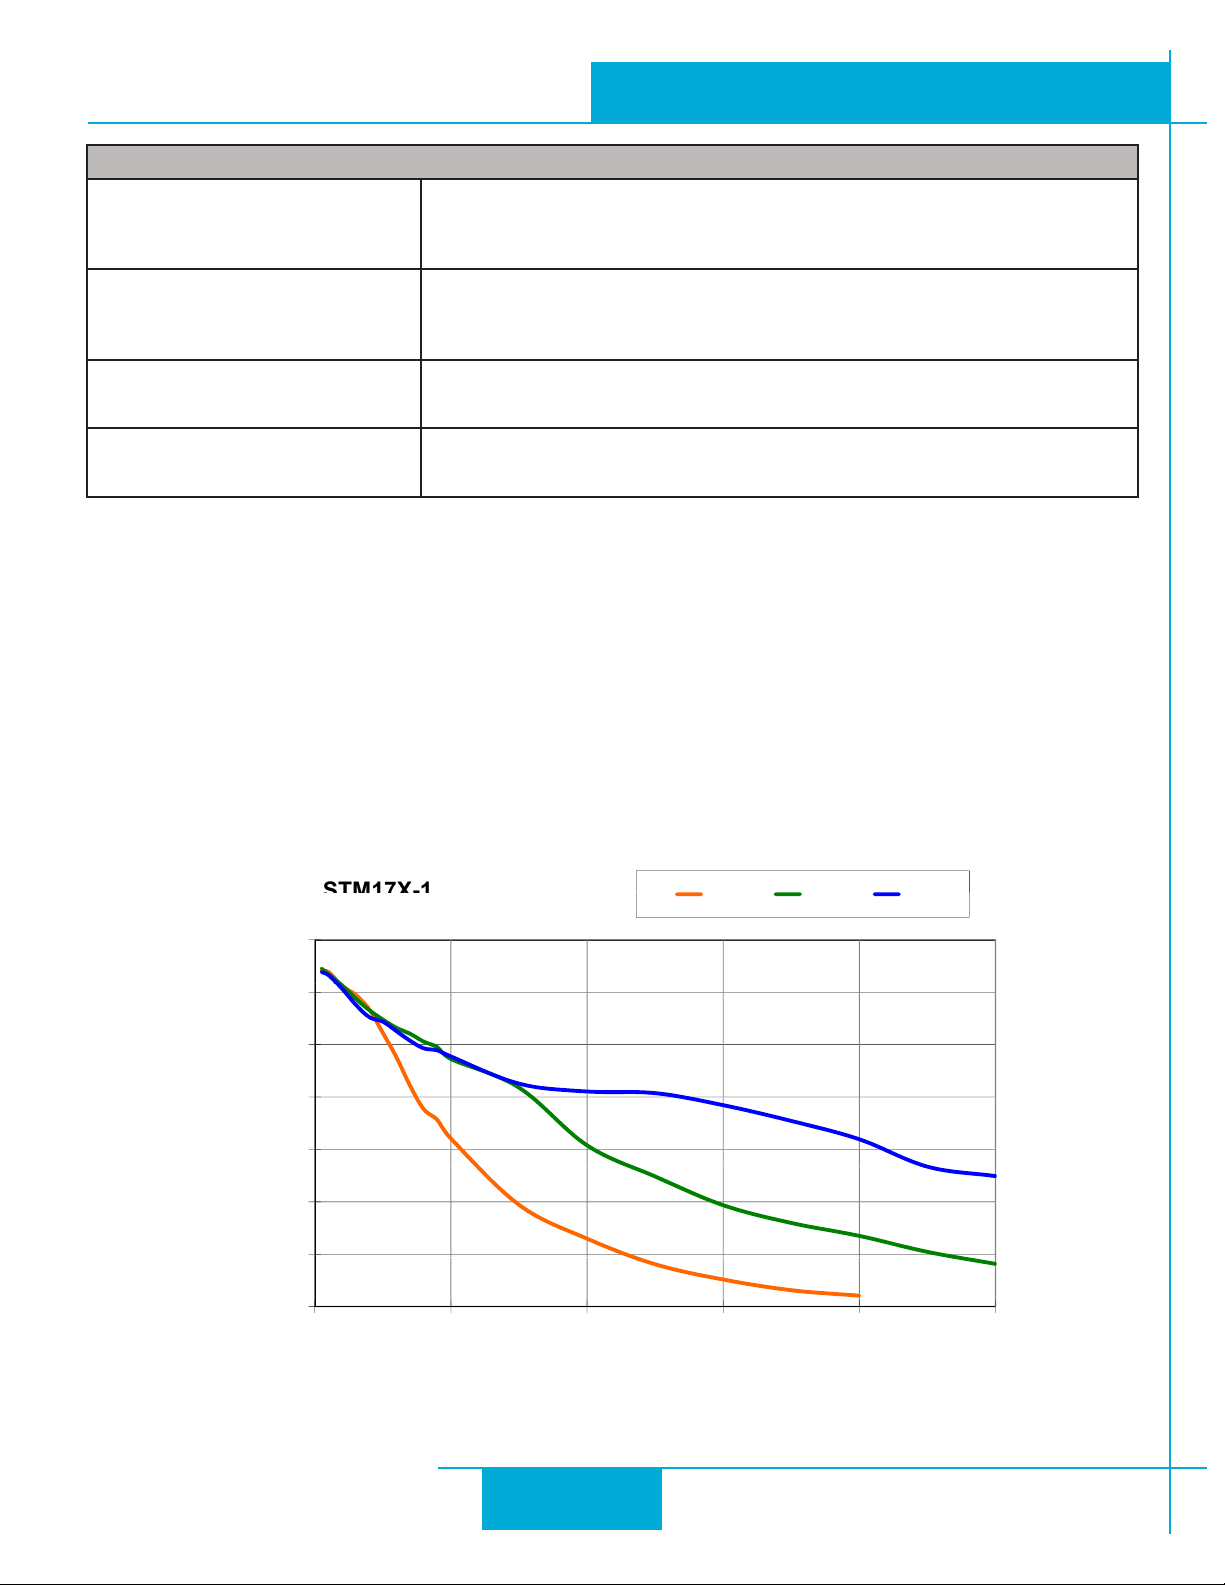
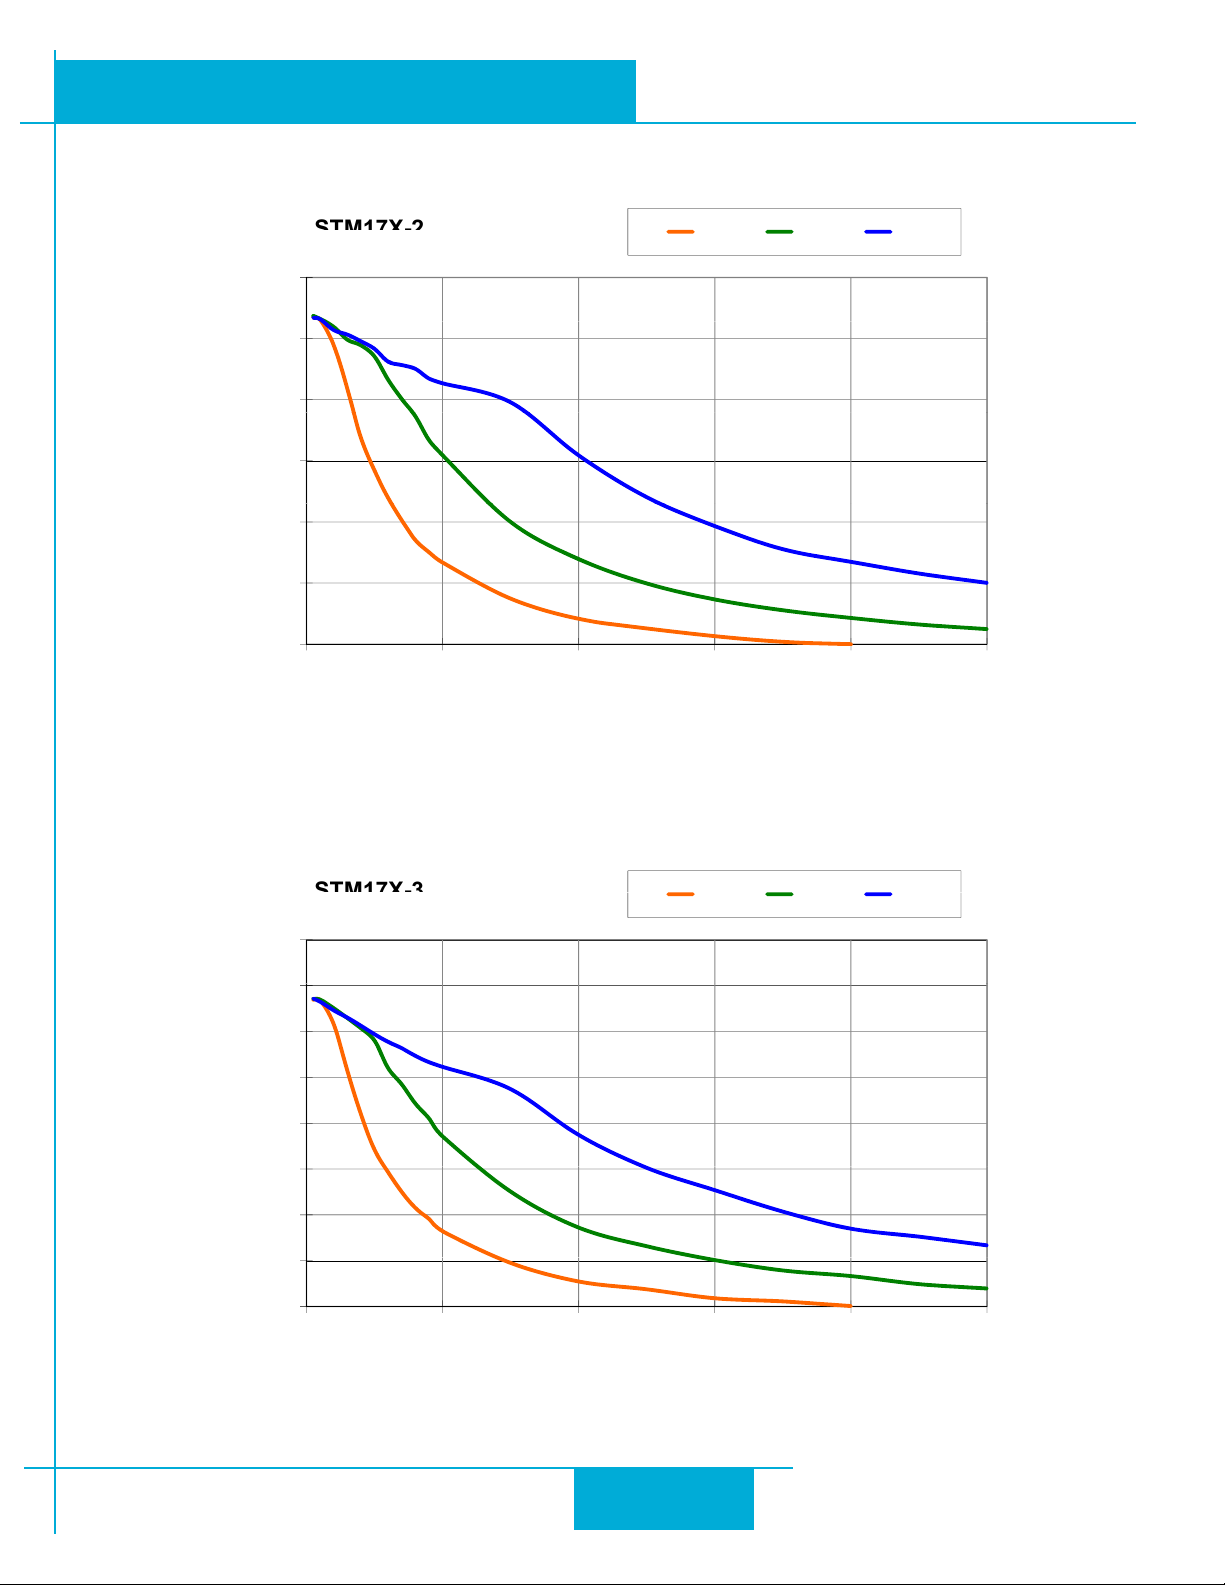
Torque-Speed Curves
Note: all torque curves were measured at 20,000 steps/rev, 1.8A motor current
26
Page 27
60
STM17X
-
2
12V
24V
48V
40
50
30
oz-in
10
20
0
0 10 20 30 40 50
rps
80
STM17X
-
3
12V
24V
48V
60
70
40
50
oz-in
20
30
0
10
0 10 20 30 40 50
rps
STM17 Hardware Manual
920-0034 rev A
9/30/2010
27
Page 28
STM17S-1AN Max Duty Cycle v s Speed
1.8 Amps @ Ambient of 40°C
80 x 80 x 6(mm) Aluminum Plate
0
20
40
60
80
100
0 10 20 30 40 50
Speed (RPS)
% Duty Cycle
12V Duty Cyc le
24V Duty Cyc le
48V Duty Cyc le
STM 17S-1AN Temperature vs. Spee d
1.8 Amps @ Ambient of 40°C
80 x 80 x6(mm) Aluminum Plate
0
20
40
60
80
100
120
140
160
0 10 20 30 40 50
Speed (RPS)
Temperature (C)
12V Temp
24V Temp
48V Temp
920-0034 rev A
9/30/2010
STM17 Hardware Manual
Drive/Motor Heating
Step motors convert electrical power from the driver into mechanical power to move a load. Because step motors are
not perfectly ecient, some of the electrical power turns into heat on its way through the motor. is heating is not so
much dependent on the load being driven but rather the motor speed and power supply voltage. ere are certain
combinations of speed and voltage at which a motor cannot be continuously operated without damage.
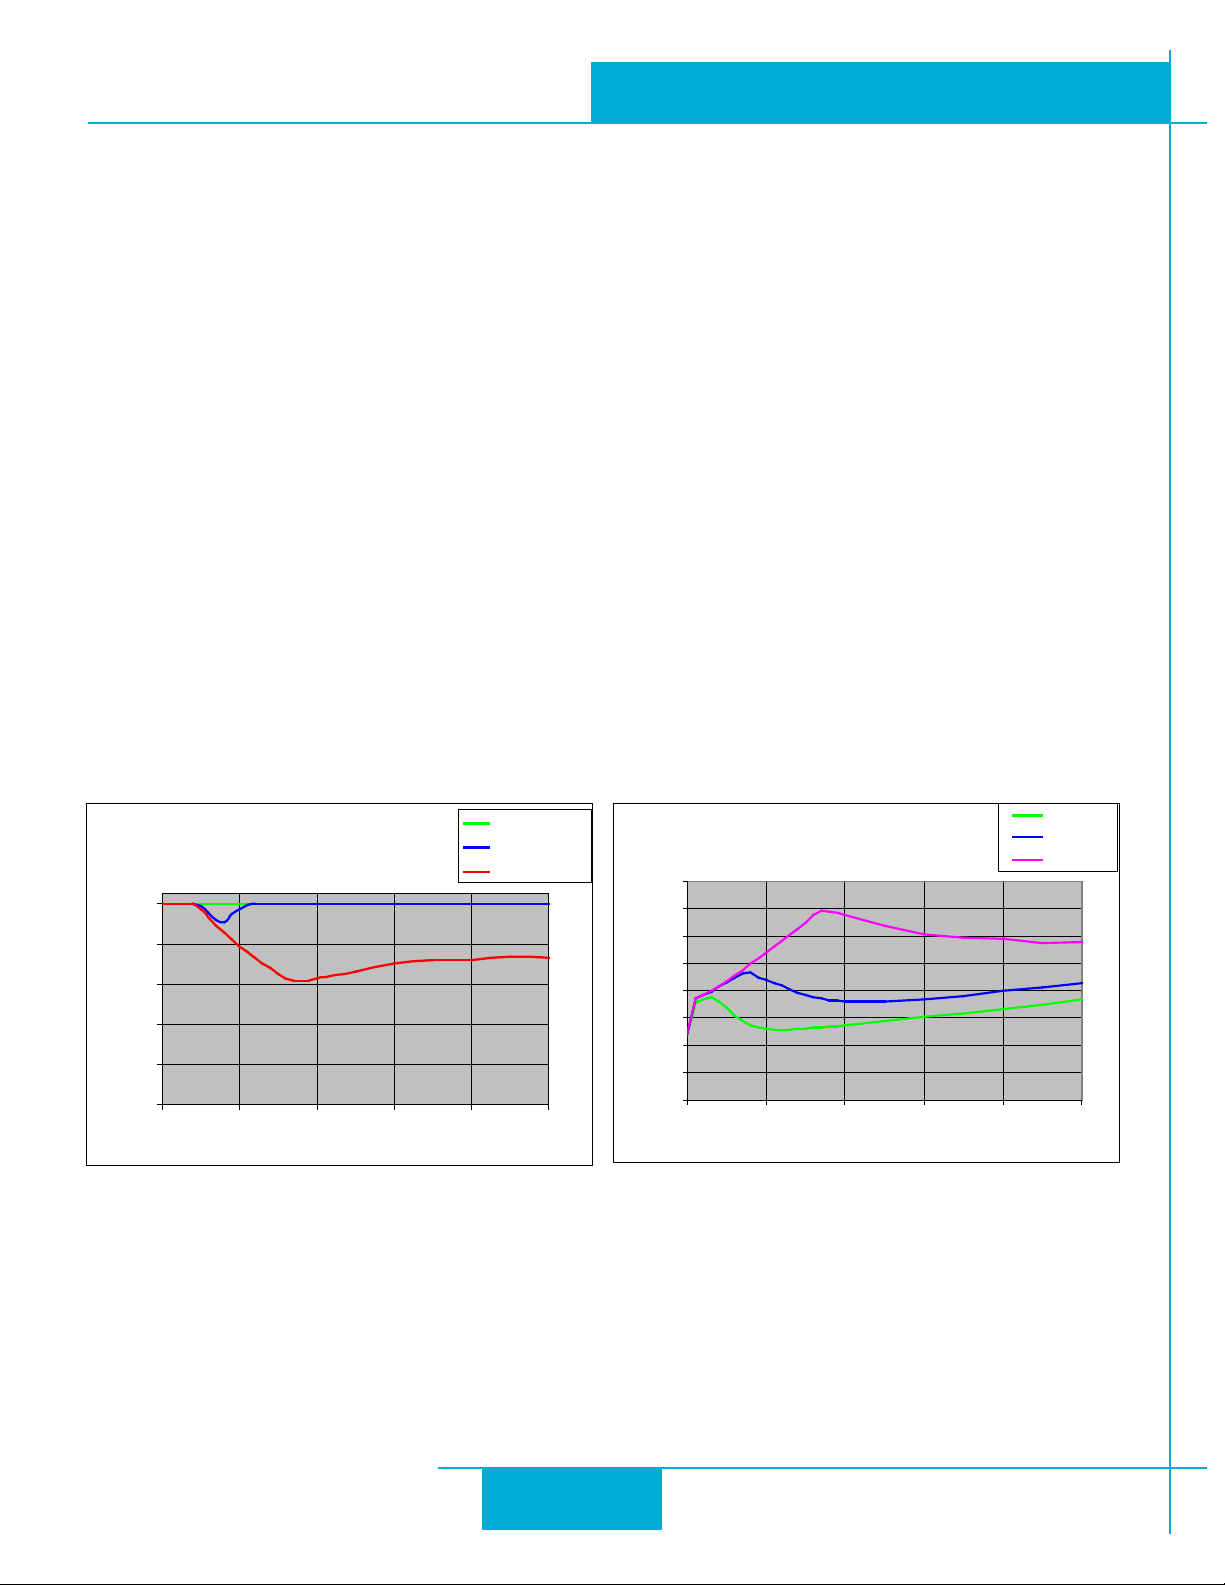
We have characterized the STM17 Drive+Motors in our lab and provided curves showing the maximum duty cycle
versus speed for each size at commonly used power supply voltages. Please refer to these curves when planning your
application.
Please also keep in mind that a step motor typically reaches maximum temperature aer 30 to 45 minutes of operation.
If you run the motor for one minute then let it sit idle for one minute, that is a 50% duty cycle. Five minutes on and ve
minutes o is also 50% duty. However, one hour on and one hour o has the eect of 100% duty because during the
rst hour the motor will reach full (and possibly excessive) temperature.
e actual temperature of the motor depends on how much heat is conducted, convected or radiated out of it. Our
measurements were made in a 40°C (104°F) environment with the motor mounted to an aluminum plate sized to provide
a surface area consistent with the motor power dissipation. Your results may vary.
Please use the curves below, which show the motor body temperature, to determine the maximum duty cycle of the
Drive+Motor under various conditions.
28
Page 29
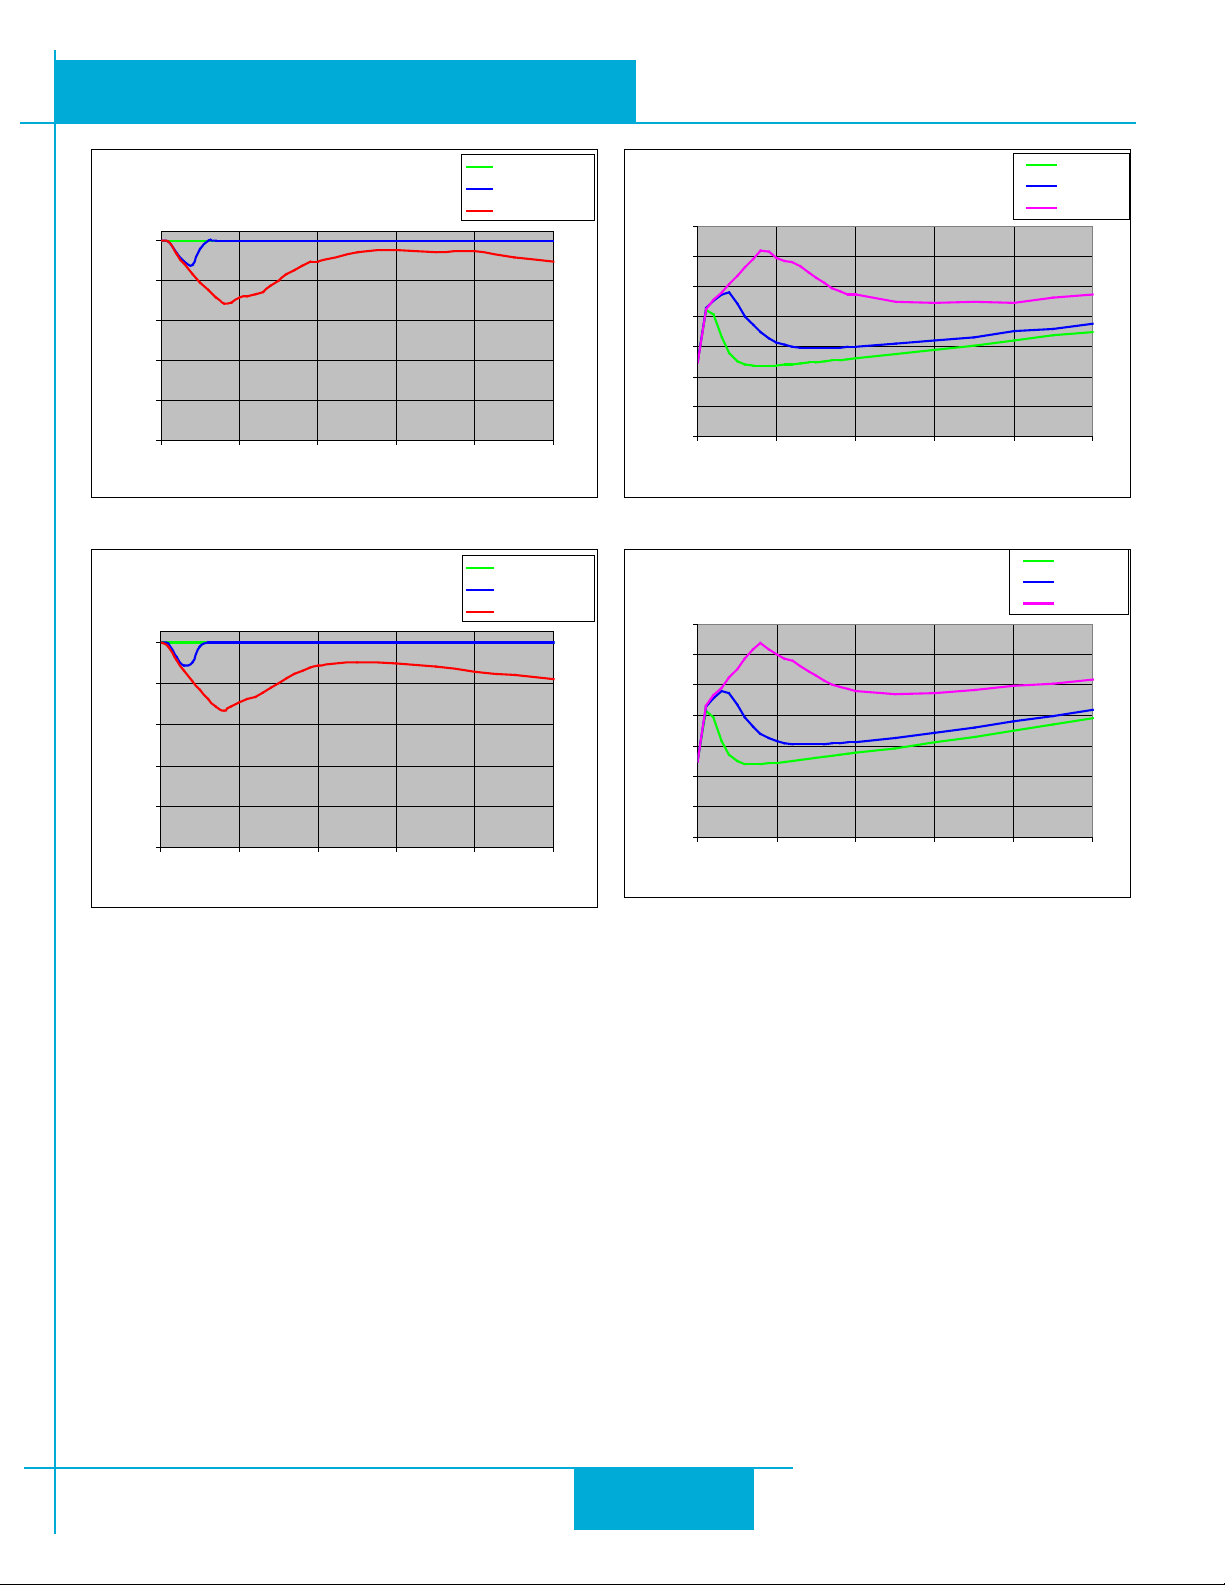
STM 17S-2AN Max Duty Cycle vs Speed
1.8 Amps @ Ambient of 40°C
80 x 80x 6(mm) Aluminum Plate
0
20
40
60
80
100
0 10 20 30 40 50
Speed (RPS)
% Duty Cycle
12V Dut y Cyc le
24V Dut y Cyc le
48V Dut y Cyc le
STM17S-2AN Temperature vs. Speed
1.8 Amps @ Ambient of 40°C
80 x 80x 6(mm) Aluminum Plate
0
20
40
60
80
100
120
140
0 10 20 30 40 50
Speed (RPS)
Temperature (C)
12V Temp
24V Temp
48V Temp
STM 17S-3AN Max Duty Cycle vs Speed
1.8 Amps @ Ambient of 40°C
80 x 80x 6(mm) Aluminum Plate
0
20
40
60
80
100
0 10 20 30 40 50
Speed (RPS)
% Duty Cycle
12V Dut y Cyc le
24V Dut y Cyc le
48V Dut y Cyc le
STM 17S-3AN Temperature vs. Spee d
1.8 Amps @ Ambient of 40°C
80 x 80x 6(mm) Aluminum Plate
0
20
40
60
80
100
120
140
0 10 20 30 40 50
Speed (RPS)
Temperature (C)
12V Temp
24V Temp
48V Temp
STM17 Hardware Manual
920-0034 rev A
9/30/2010
29
Page 30
920-0034 rev A
9/30/2010
STM17 Hardware Manual
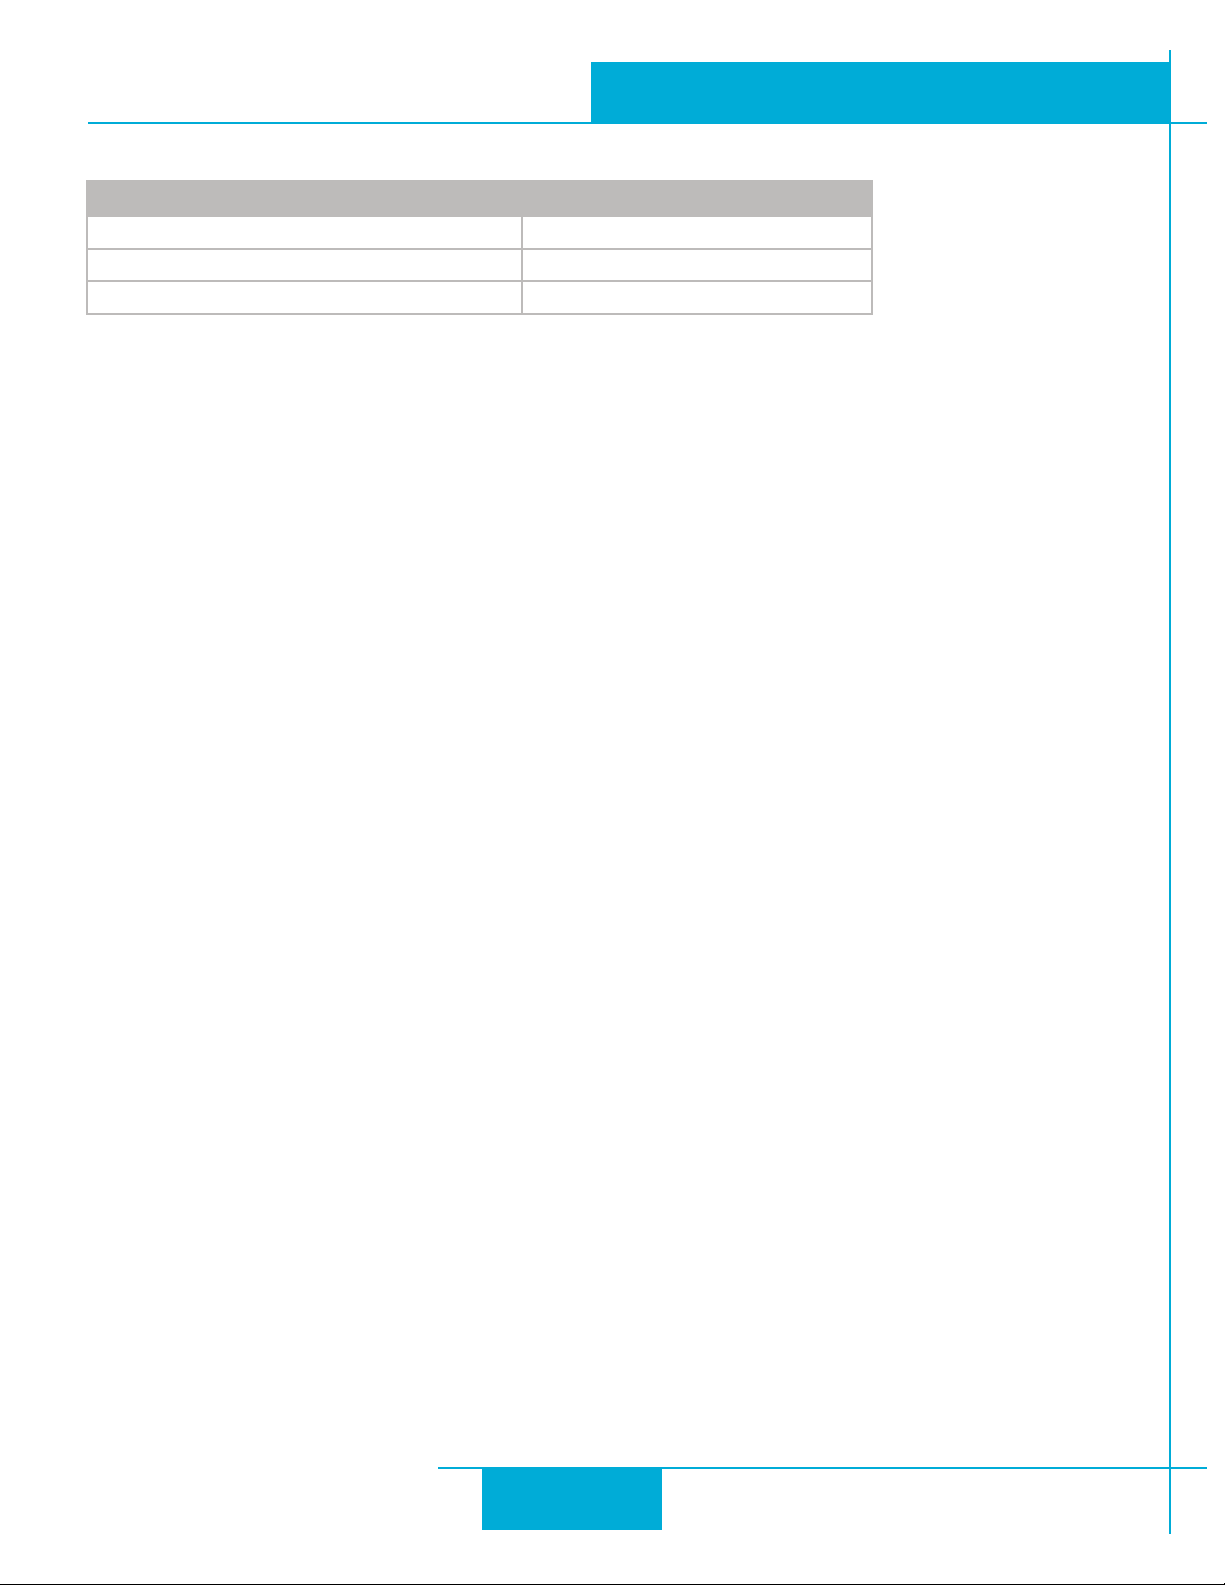
Mating Connectors and Accessories
Mating Connector (Type) PArt no
DC Power (2-position, screw terminal) Weidmuller 1615780000
I/O (11-position, spring cage) Phoenix 1881419
Comm (5-position, spring cage) Phoenix 1881354
Accessories
USB-Serial Adapter with one RS-232 port and one RS-485 port for programming all units: P/N 8500-003
DC Power Supplies:
24V, 50W switching power supply, P/N PS50A24
24 V, 150W switching power supply, P/N PS150A24
48 V, 320W switching power supply, P/N PS320A48
Regeneration Clamp for Applications with High Inertial Loads
RC-050
30
Page 31
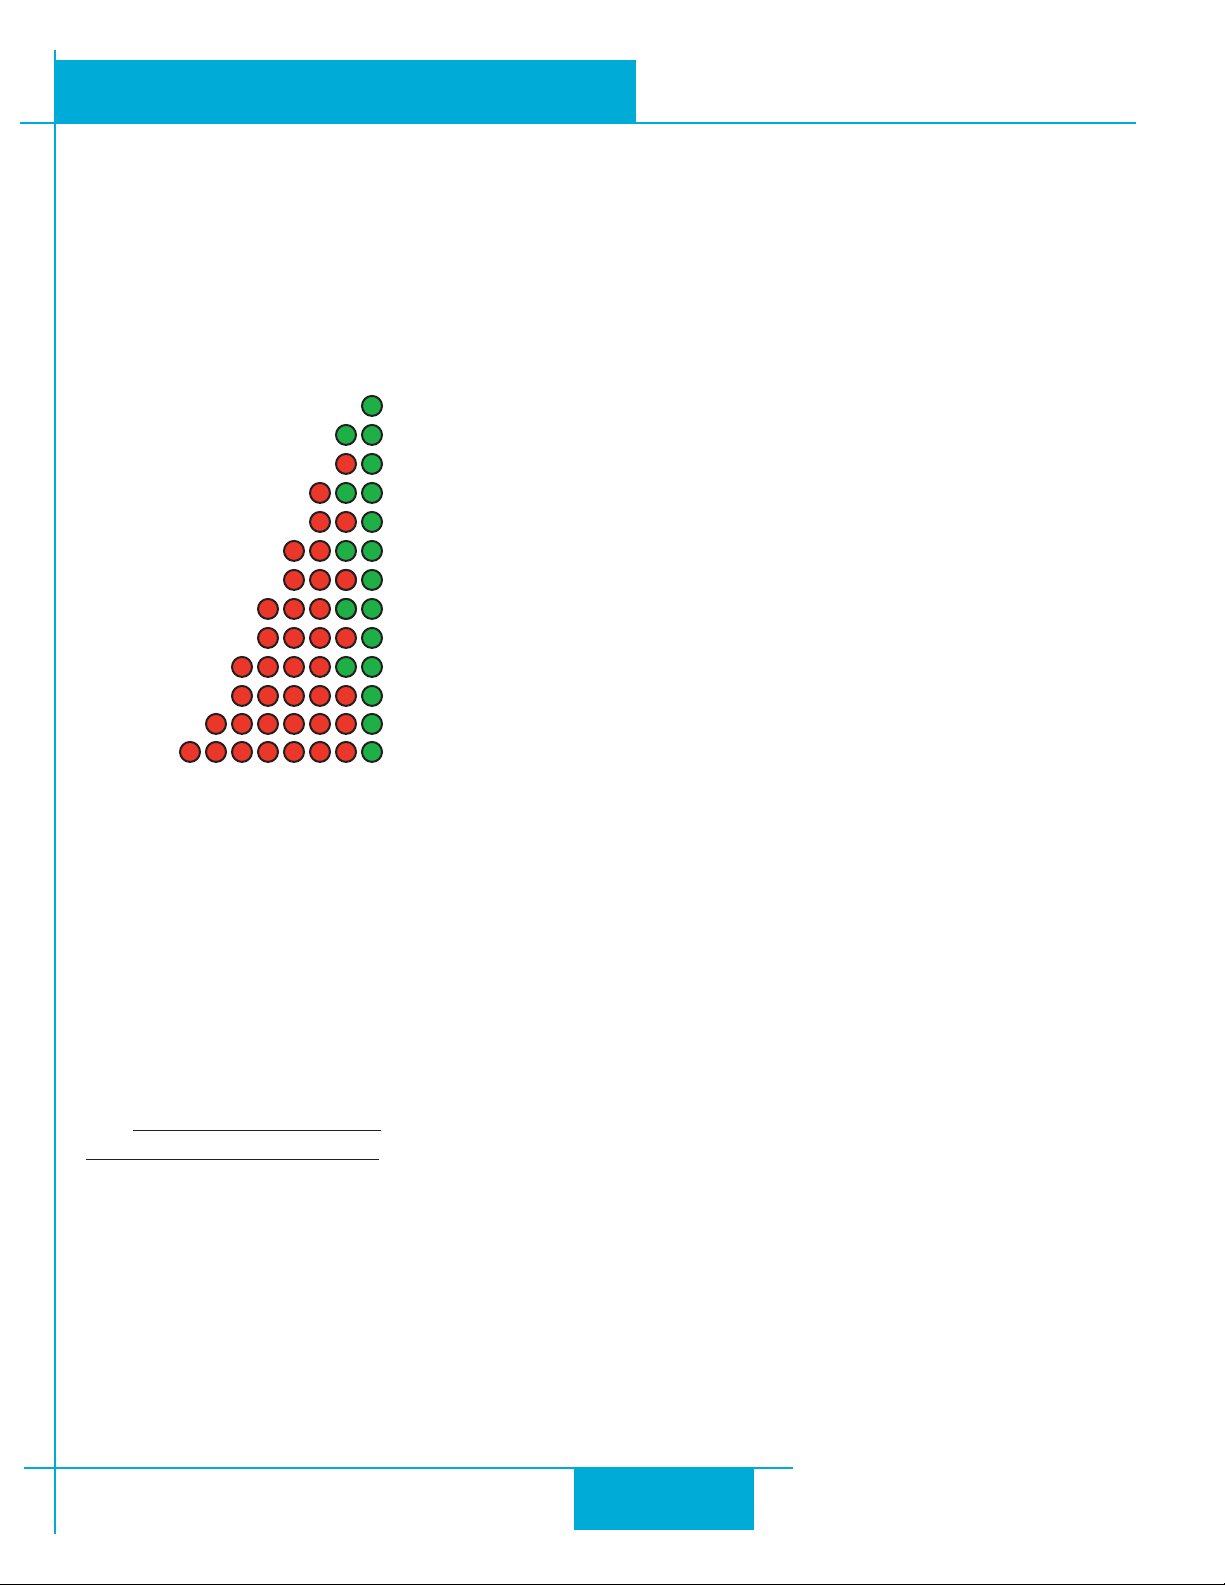
Code Condition
solid green no alarm, motor disabled
flashing green no alarm, motor enabled
1 red, 1 green motor stall (optional encoder only)
1 red, 2 green
move attempted while drive disabled
2 red, 1 green
ccw limit
2 red, 2 green cw limit
3 red, 1 green drive overheating
3 red, 2 green internal voltage out of range
4 red, 1 green power supply overvoltage
4 red, 2 green power supply undervoltage
5 red, 1 green over current / short circuit
6 red, 1 green open motor winding
7 red, 1 green serial communication error
920-0034 rev A
Re-Order from
omegamation.com
Omegamation
TM
1-888-55-OMEGA
1-888-55-66342
1-888-55-66342
STM17 Hardware Manual
9/30/2010
LED Status & Error Codes
e STM drive+motor includes red and green LEDs to indicate status. When the motor is enabled, the green
LED ashes slowly. When the green LED is solid, the motor is disabled. Errors are indicated by combinations of
red and green “ashes” as follows:
Contacting Applied Motion Products
Corporate Headquarters
404 Westridge Drive
Watsonville, CA 95076
(831) 761-6555
fax (831) 761-6544
web www.applied-motion.com
[email protected]
31
 Loading...