

Page 1
SSDC03/06/10
StepSERVO Drive
Hardware Manual
Rev. 1.0
10212018
Page 2
SSDC-R/C/IP Hardware Manual
目目
1 Introduction .........................................................................................................3
1.1 Features ..................................................................................................................3
1.2 Block Diagram ........................................................................................................4
1.3 Safety Instructions ..................................................................................................5
2 Getting Started ....................................................................................................6
2.1 Installing Software ..................................................................................................7
2.2 RS-485/422 communication port (-R type) .............................................................9
2.3 CANopen Connecting communication (-C type) ......................................................11
2.4 Setting Node ID and baud rate .................................................................................12
2.5 Choosing the Right COM Port ................................................................................14
2.6 Connecting the Drive to Your PC using Ethernet ....................................................15
2.7 Connecting the Power Supply ................................................................................19
2.8 Choosing a Power Supply ......................................................................................20
2.9 Connecting the Motor .............................................................................................32
3 Inputs and Outputs ..............................................................................................33
3.1 Digital Inputs ..........................................................................................................34
3.2 Digital Outputs .......................................................................................................36
3.3 Analog Inputs .........................................................................................................38
3.4 Encoder Output .......................................................................................................38
3.5 Secondary Encoder Input.........................................................................................39
4 Mounting the Drive .............................................................................................40
5 LED Error Codes .................................................................................................40
6 Reference Materials .............................................................................................41
6.1 Drive Mechanical Outlines ......................................................................................41
6.2 Technical Specifications .........................................................................................42
6.3 Recommended Motors ...........................................................................................43
6.4 Mechanical Dimension ...........................................................................................44
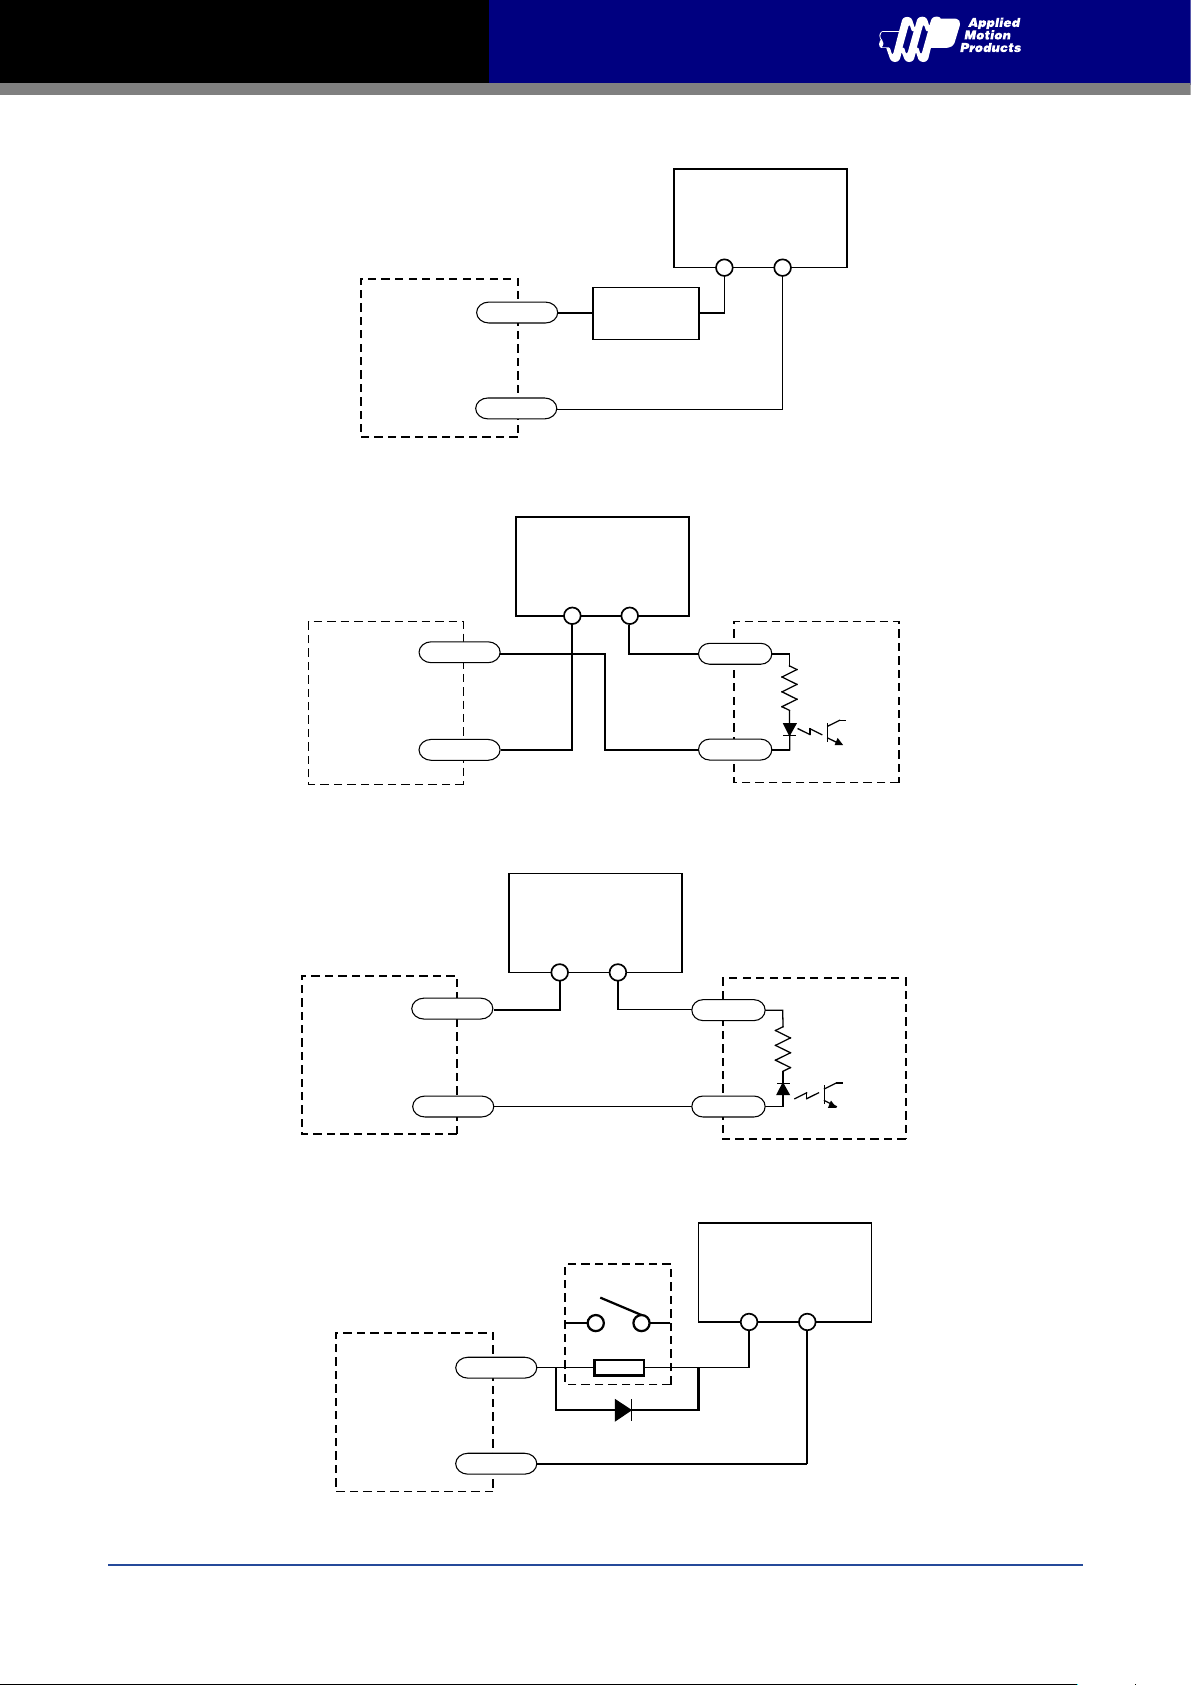
6.5 Torque Curves ........................................................................................................47
7 Accessories .........................................................................................................49
7.1 Standard Accessories (Included) ............................................................................49
7.2 Optional Accessories (Sold Separately) ..................................................................49
8 Contacting Applied Motion Products ..................................................................52
Rev. 1.0
7/31/2019
2
Page 3
SSDC-R/C/IP Hardware Manual
1 Introduction
Thank you for selecting the Applied Motion Products SSDC series StepSERVO drive and motor. SSDC series combines servo
technology with a stepper motor to create a product with exceptional feature and broad capability.
The SSDC series is a high performance, intelligent StepSERVO system with multi-axes field bus control.
1.1 Features
• Programmable, digital StepSERVO drive and motor package
• Control modes:
Velocity Control: Digital signal control, Analog control, eSCL command, Q programming
Position Control: Digital signal control, Analog control, eSCL command, Q programming
Torque Control: Analog control, eSCL command, Q programming
• Multi-operation modes:
Closed-loop Stepper control mode
Closed-loop Servo control mode
Full closed-loop mode
• Current output
SSDC03 output current: continuous 3A/phase (peak of sin), boost 4A(1.5s)
SSDC06 output current: continuous 6A/phase (peak of sin), boost 7.5A(1.5s)
SSDC10 output current: continuous 10A/phase (peak of sin), boost 15A(1.5s)
• Wide range input voltage:
SSDC03: 12~48VDC
SSDC06: 24~70VDC
SSDC10: 24~70VDC
• Encoder resolution:
20000 counts/rev (HT17/23/24/34 SSmotor)
4096 counts/rev (HT11 SSmotor)
• Differential encoder outputs (ENC A+/-, ENC B+/-, ENC Z+/-), 26C31 line driver, 20 mA sink or source max
• Support secondary encoder signal input(single-ended or differential) for full closed-loop control
• Abundant I/O interface
8 optically isolated digital inputs,5-24VDC
4 optically isolated digital outputs,max30V/100mA
2 analog inputs can be configured to 0-5V, 0-10V, ±5V or ±10V signal ranges
• Communication
-R: Dual-port RJ45 connector, RS-485/422, Modbus/RTU protocol
-C: Dual-port RJ45 connector, CANopen, conform CiA301 and CiA402, RS-232 serial port for configuration
-IP: Dual-port RJ45 connector, eSCL command, Modbus/TCP, EtherNet/IP protocol
3
Rev. 1.0
7/31/2019
Page 4
SSDC-R/C/IP Hardware Manual
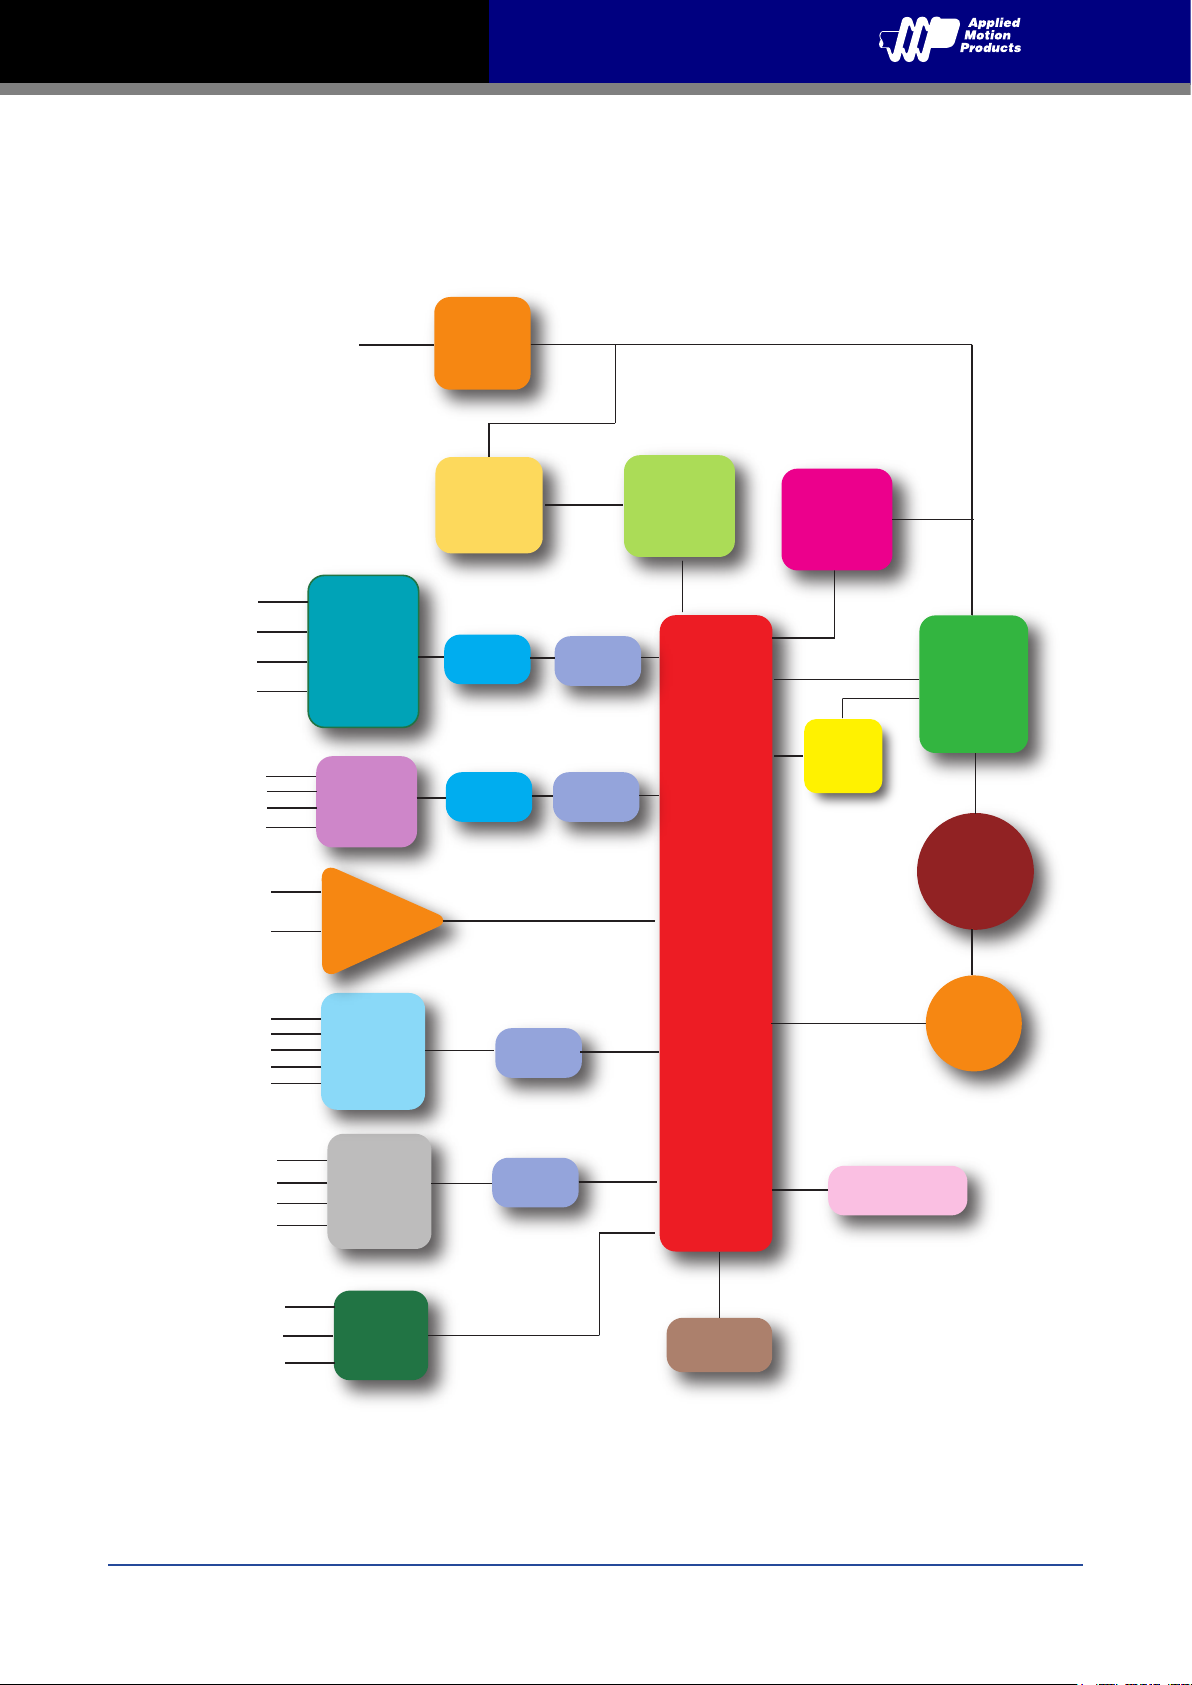
1.2 Block Diagram
SSDC Block Diagram
Power Supply:
SSDC06/10: 24-70VDC
SSDC03: 12-48VDC
X1+
X1-
X2+
X2-
X3+
X3-
X4+
X4-
ANALOG1
ANALOG2
High
Speed
Input
Optical
Ioslation
Input
Optical
Ioslation
Operational
Amplifter
EMC
Filter
DC Input
Power
Converter
Digital
Filter
Digital
Filter
Software
Filter
Software
Filter
Internal
Logic
Supply
DSP
Voltage
Temp.
Det.
Mosfet
PWM
Power
Amplifier
Over
Current
Det.
Motor
Rev. 1.0
7/31/2019
X5
X6
X7
X8
XCOM
Y1+/Y2+/-
Y3+/Y4+/-
A+/-
B+/-
Z+/-
Single
Ended
Input
Ioslation
Output
Optical
Ioslation
Encoder
Output
Software
Filter
Software
Filter
Encoder
Communication
LED
4
Page 5
SSDC-R/C/IP Hardware Manual
1.3 Safety Instructions
Only qualified personnel should transport, assemble, install, operate, or maintain this equipment. Properly qualified
personnel are persons who are familiar with the transport, assembly, installation, operation, and maintenance of motors, and
who meet the appropriate qualifications for their jobs.
To minimize the risk of potential safety problems, all applicable local and national codes regulating the installation and
operation of equipment should be followed. These codes may vary from area to area and it is the responsibility of the
operating personnel to determine which codes should be followed, and to verify that the equipment, installation, and
operation are in compliance with the latest revision of these codes.
Equipment damage or serious injury to personnel can result from the failure to follow all applicable codes and standards.
Applied Motion Products does not guarantee the products described in this publication are suitable for a particular
application, nor do they assume any responsibility for product design, installation, or operation.
Read all available documentation before assembly and operation. Incorrect handling of the products referenced in this manual
can result in injury and damage to persons and machinery.
All technical information concerning the installation requirements must be strictly adhered to.
It is vital to ensure that all system components are connected to earth ground. Electrical safety is impossible without a lowresistance earth connection.
This product contains electrostatically sensitive components that can be damaged by incorrect handling. Follow qualified
anti-static procedures before touching the product.
During operation keep all covers and cabinet doors shut to avoid any hazards that could possibly cause severe damage to the
product or personal health.
During operation, the product may have components that are live or have hot surfaces.
Never plug in or unplug the Integrated Motor while the system is live. The possibility of electric arcing can cause damage.
Be alert to the potential for personal injury. Follow recommended precautions and safe operating practices emphasized with
alert symbols. Safety notices in this manual provide important information. Read and be familiar with these instructions
before attempting installation, operation, or maintenance. The purpose of this section is to alert users to the possible safety
hazards associated with this equipment and the precautions necessary to reduce the risk of personal injury and damage
to equipment. Failure to observe these precautions could result in serious bodily injury, damage to the equipment, or
operational difficulty.
5
Rev. 1.0
7/31/2019
Page 6
SSDC-R/C/IP Hardware Manual
2 Getting Started
The following items are needed:
• A 12-70VDC power supply, see the section below entitled “Choose a Power Supply” for helping to choose the right one.
• A compatible StepSERVO motor, please see the section below entitled “Recommended Motor”
• A small flat blade screwdriver for tightening the connectors screw(included)
• A PC running Microsoft Windows XP/Vista/7/8/10 (Using serial communication port.
• Install the StepSERVO Quick Tuner software
(download from Applied Motion Products website: www.applied-motion.com )
• A power cable(included)
• Communiation cables are Included,they can be used to do the daisy-chain connectionas well as configure the drive.
• Optional extended motor cable(Sold separately)
• Optional extended encoder cable(Sold separately)
• Optional extended I/O cable(Sold separately)
Rev. 1.0
7/31/2019
6
Page 7
SSDC-R/C/IP Hardware Manual
2.1 Installing Software
StepSERVO Quick Tuner is the PC based software application used to configure, and perform servo tuning, drive testing and
evaluation of the StepSERVO products. System servo control gains, drive functionality and I/O configuration are set with
StepSERVO Quick Tuner. It also contains an oscilloscope function to help set the servo control gains.
• Download the StepSERVO Quick Tuner from the Applied Motion Products website and install it.
• Launch the software by clicking Start-----Programs ----Applied Motion Products connect the drive to PC by
communication cable, configure the network on PC. Please see the section below entitled “Connecting the Drive to Your
PC”.
• Connect the drive to the Power Supply.
• Connect the motor to the drive.
• Power up the drive.
• Click the ‘connect’ bottom, the software will recognize your drive, display the model and firmware version and be ready
for action.
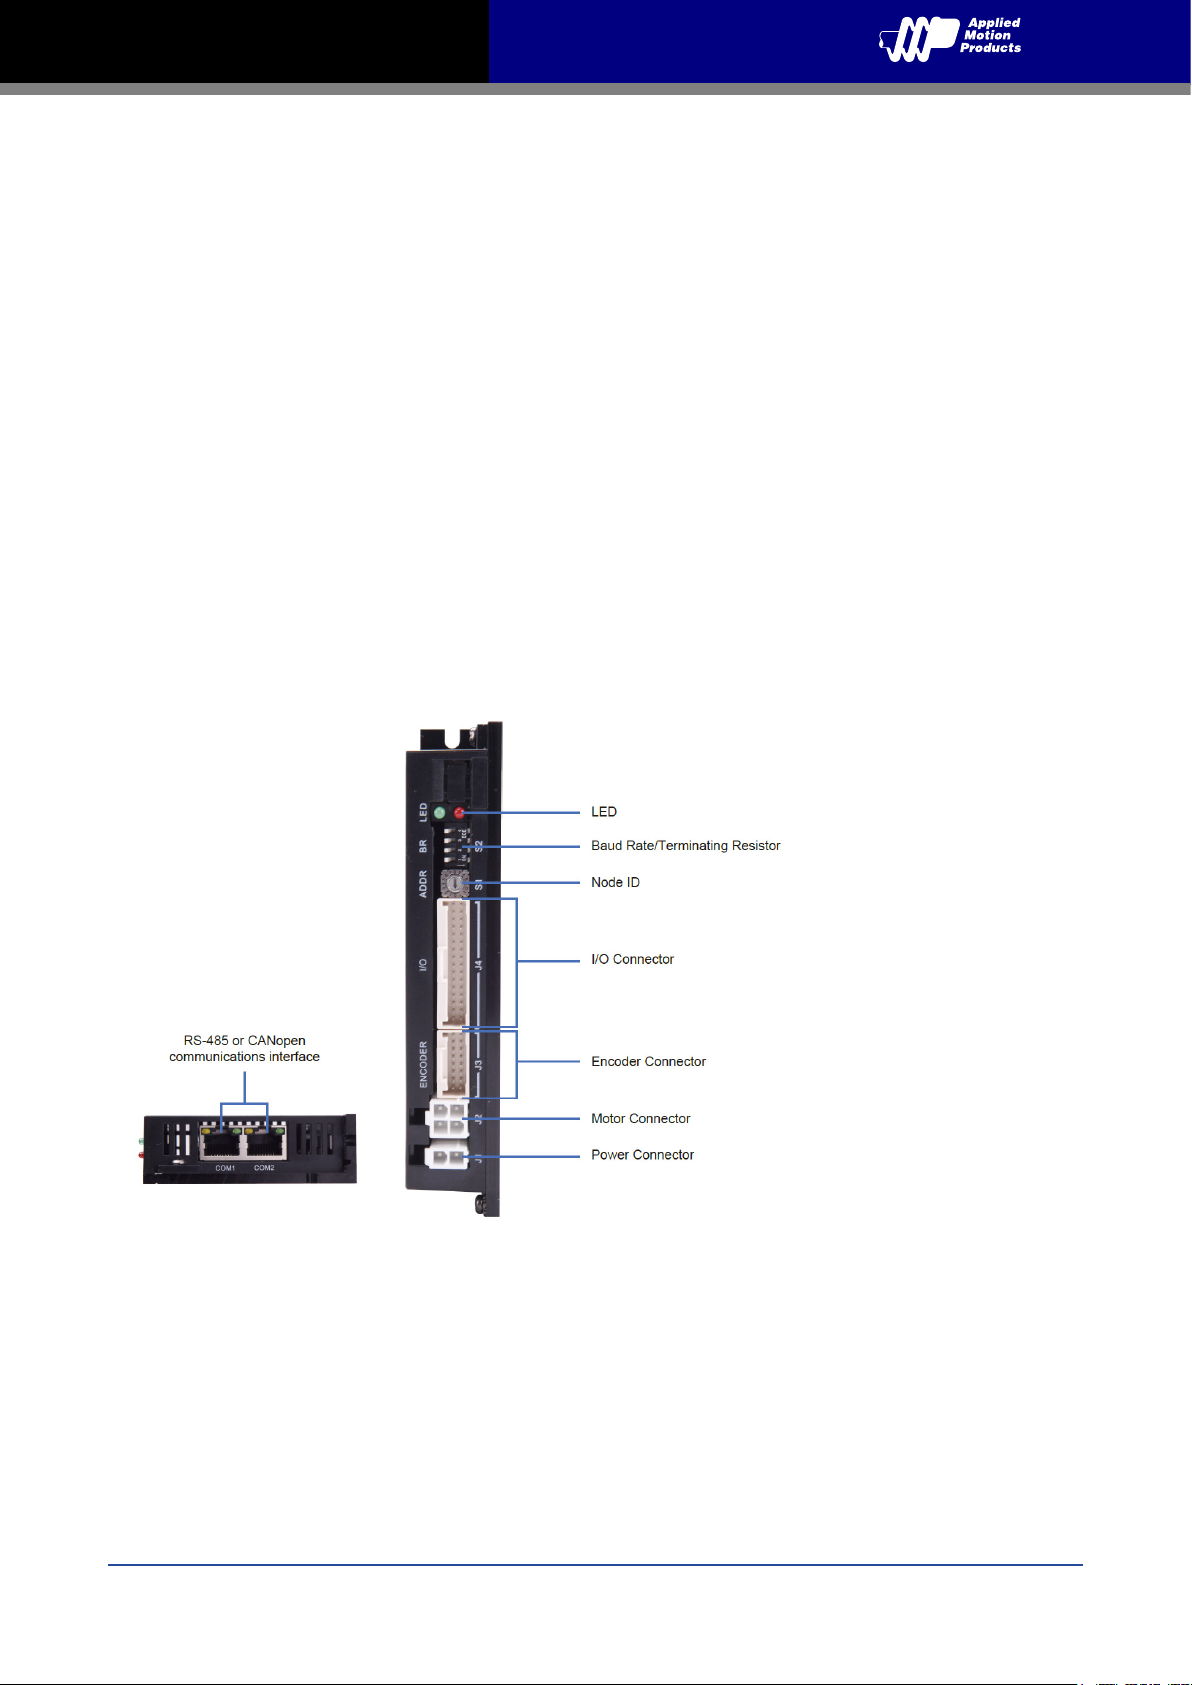
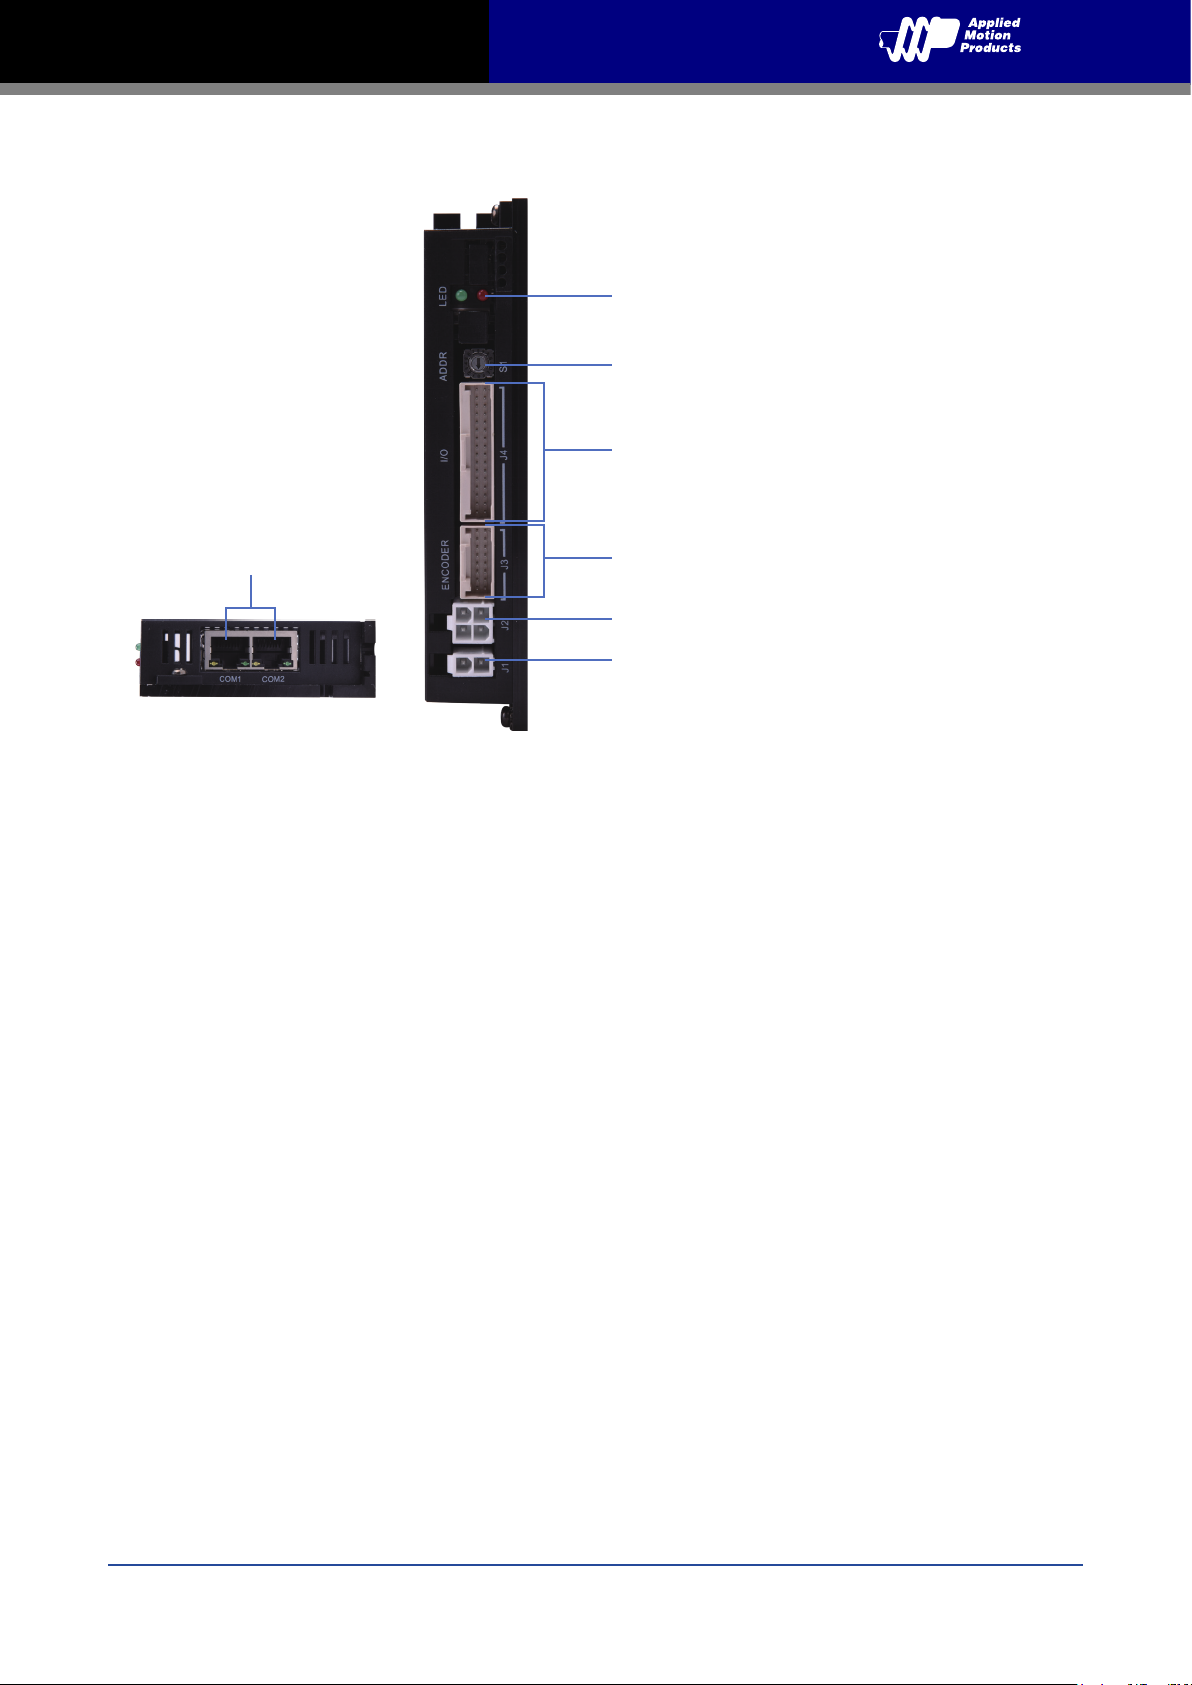
The connectors and other points of interest are below:
SSDC-R, RS485 Communication type / SSDC-C, CANopen Communication type
7
Rev. 1.0
7/31/2019
Page 8
SSDC-R/C/IP Hardware Manual
SSDC-D, Modbus/TCP Communication type / SSDC-IP, EtherNet/IP Communication type
LED
Node ID
I/O Connector
Ethernet communications interface
Encoder Connector
Motor Connector
Power Connector
Rev. 1.0
7/31/2019
8
Page 9
SSDC-R/C/IP Hardware Manual
1 8
1 8
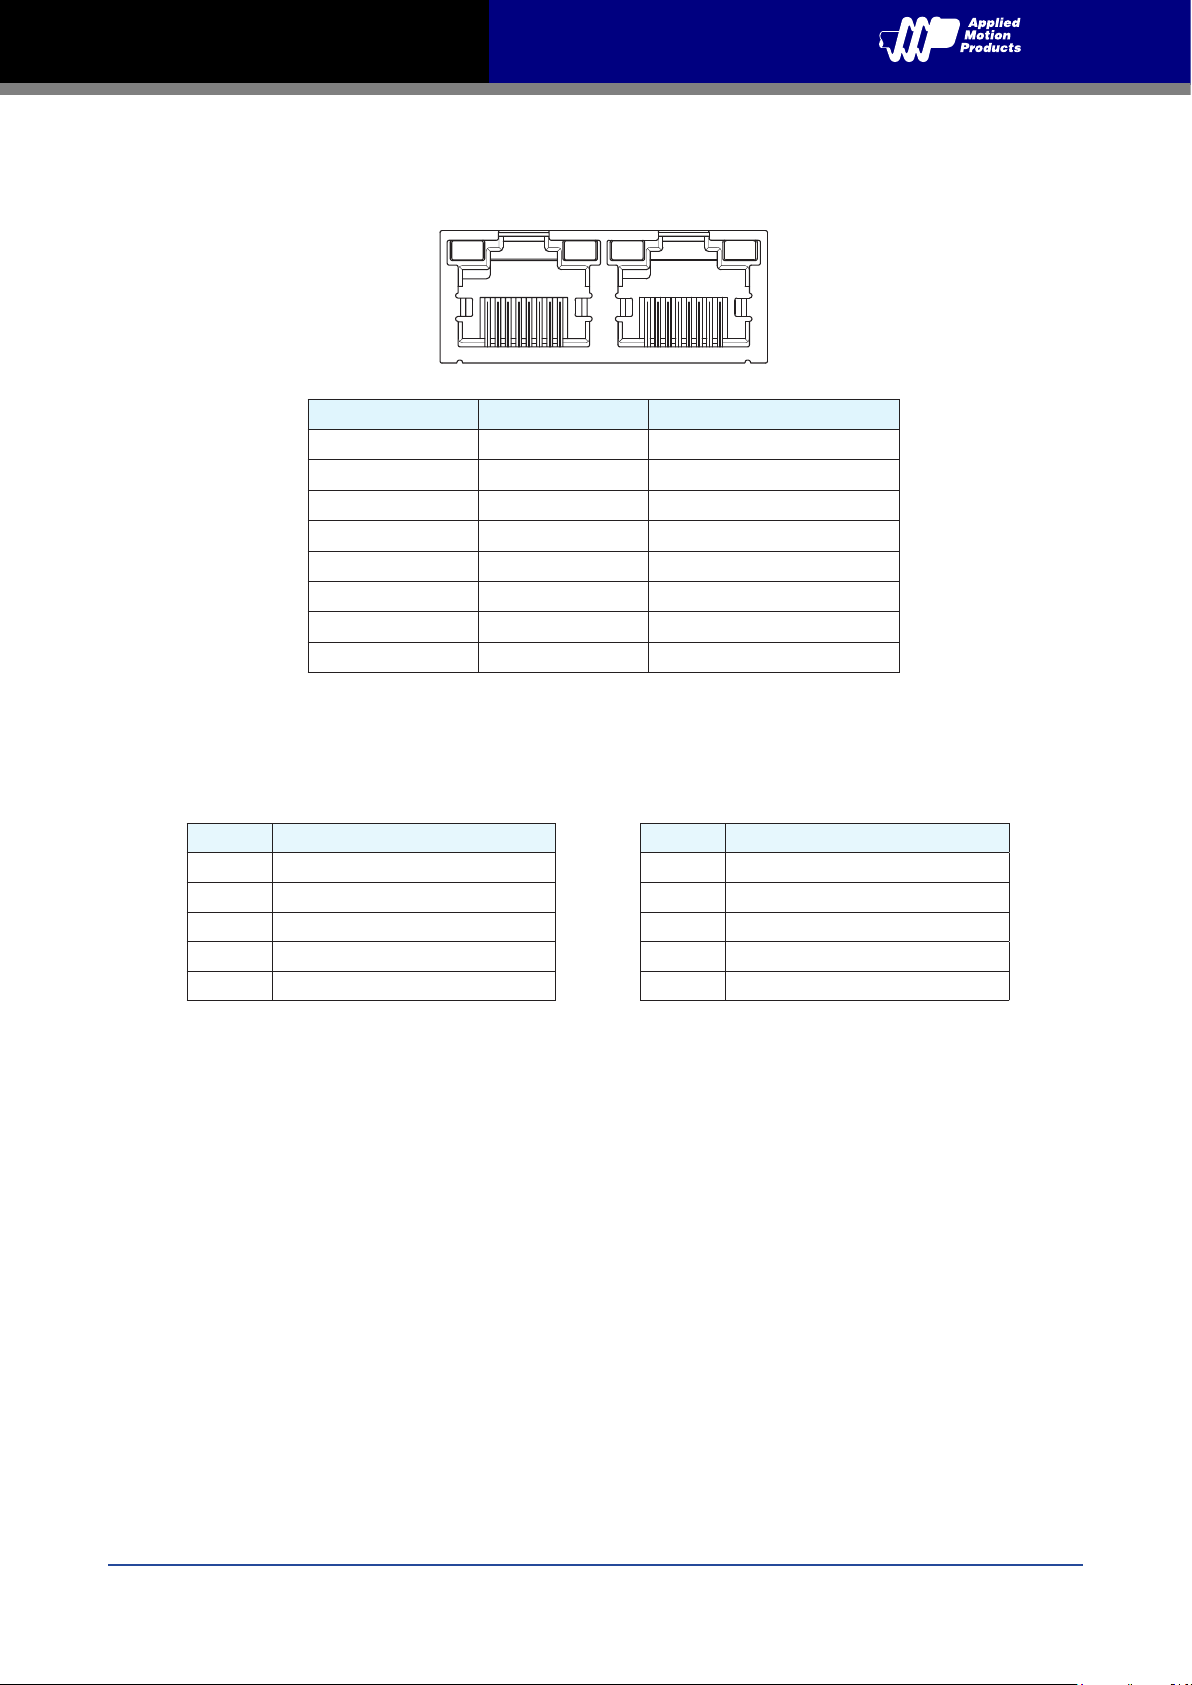
2.2 RS-485/422 communication port (-R type)
RS-485/422 communication port
PIN Definition Color
1 RX+ Orange/White
2 RX- Orange
3 TX+ Green/White
4 NC Blue
5 NC Blue/White
6 TX- Green
7 GND Brown/Whitelv
8 GND Brown
Connecting to a Host using RS-485
Before configure the drive by StepSERVO Quick tuner software, use the CAT5 cable to connect the drive(COM1 or COM2)
and host.
RS-485 four-wire connection RS-485 two-wire connection
Drive
RX+ Connect to the host’s TX+
RX- Connect to the host’s TX-
TX+ Connect to the host’s RX+
TX- Connect to the host’s RX-
GND Connect to the host’s GND
Connection
Drive Connection
RX+ Connect to the host’s +
RX- Connect to the host’s -
TX+ Connect to the host’s +
TX- Connect to the host’s -
GND Connect to the host’s GND
(NOTE: The RS-485 port on the drive is isolated from internal circuitry of the drive. So the GND of each drive’s RS-485 port
must be connected together. The first drive’s GND of the RS-485 port must be connected to the GND of RS-485 port on the
host PC or Controller)
9
Rev. 1.0
7/31/2019
Page 10
SSDC-R/C/IP Hardware Manual
RS-485 network connection
Multiple –R model drive network can be built via dual RS-485 communication port by daisy chain cable or network cable
provided.
RS-485 Four-wire Configuration
RS-485 four-wire system utilize separate transmit and receive wires. One pair of wires connect the host’s transmit
signals(TX+/TX-) to each drive’s RX+/RX- receive terminals. The other pair connects the drive’s TX+/TX- terminals to the
host’s receive signals. A logical ground terminal is provided on each drive and can be used to keep all the drives at the same
ground potential. The first drive’s logical GND of the RS-485 bus must connect to host’s ground.
Four-wire Connection
Connect the drive’s RX+ to the TX+ terminal of the host controller, and connect the drive’s RX- to the TX- terminal of the host
controller. Connect the drive’s TX+ to the RX+ terminal of the host controller, and connect the drive’s TX- to the RX- terminal
of the host controller.
Connect the drive’s GND and the host’s GND to a same ground.
RS-485 Tow-wire Configuration
In a two-wire system, the data transmitting and receiving use a same cable. The host must stop its transmitting before
receiving data. That means the host must stop transmit data before drive begins to answer a query which just come from
the host, otherwise the host cannot receive any data witch sent from a drive. There is a transmit delay parameter that can be
adjusted to compensate for a host that is slow to disable its transmitter. This adjustment can be set over the network using
the TD command, it also can be set by using the StepSERVO Quick Tuner software. Users can set a shorter transmit delay in a
four-wire system.
Two-wire connection
The RX+ and TX+ of the drive connect to the host’s + in parallel. The RX- and TX- of the drive connect to the host’s - in
parallel. Connect the drive’s GND and the host’s GND to a same ground.
Rev. 1.0
7/31/2019
10
Page 11
SSDC-R/C/IP Hardware Manual
2.3 CANopen Connecting communication (-C type)
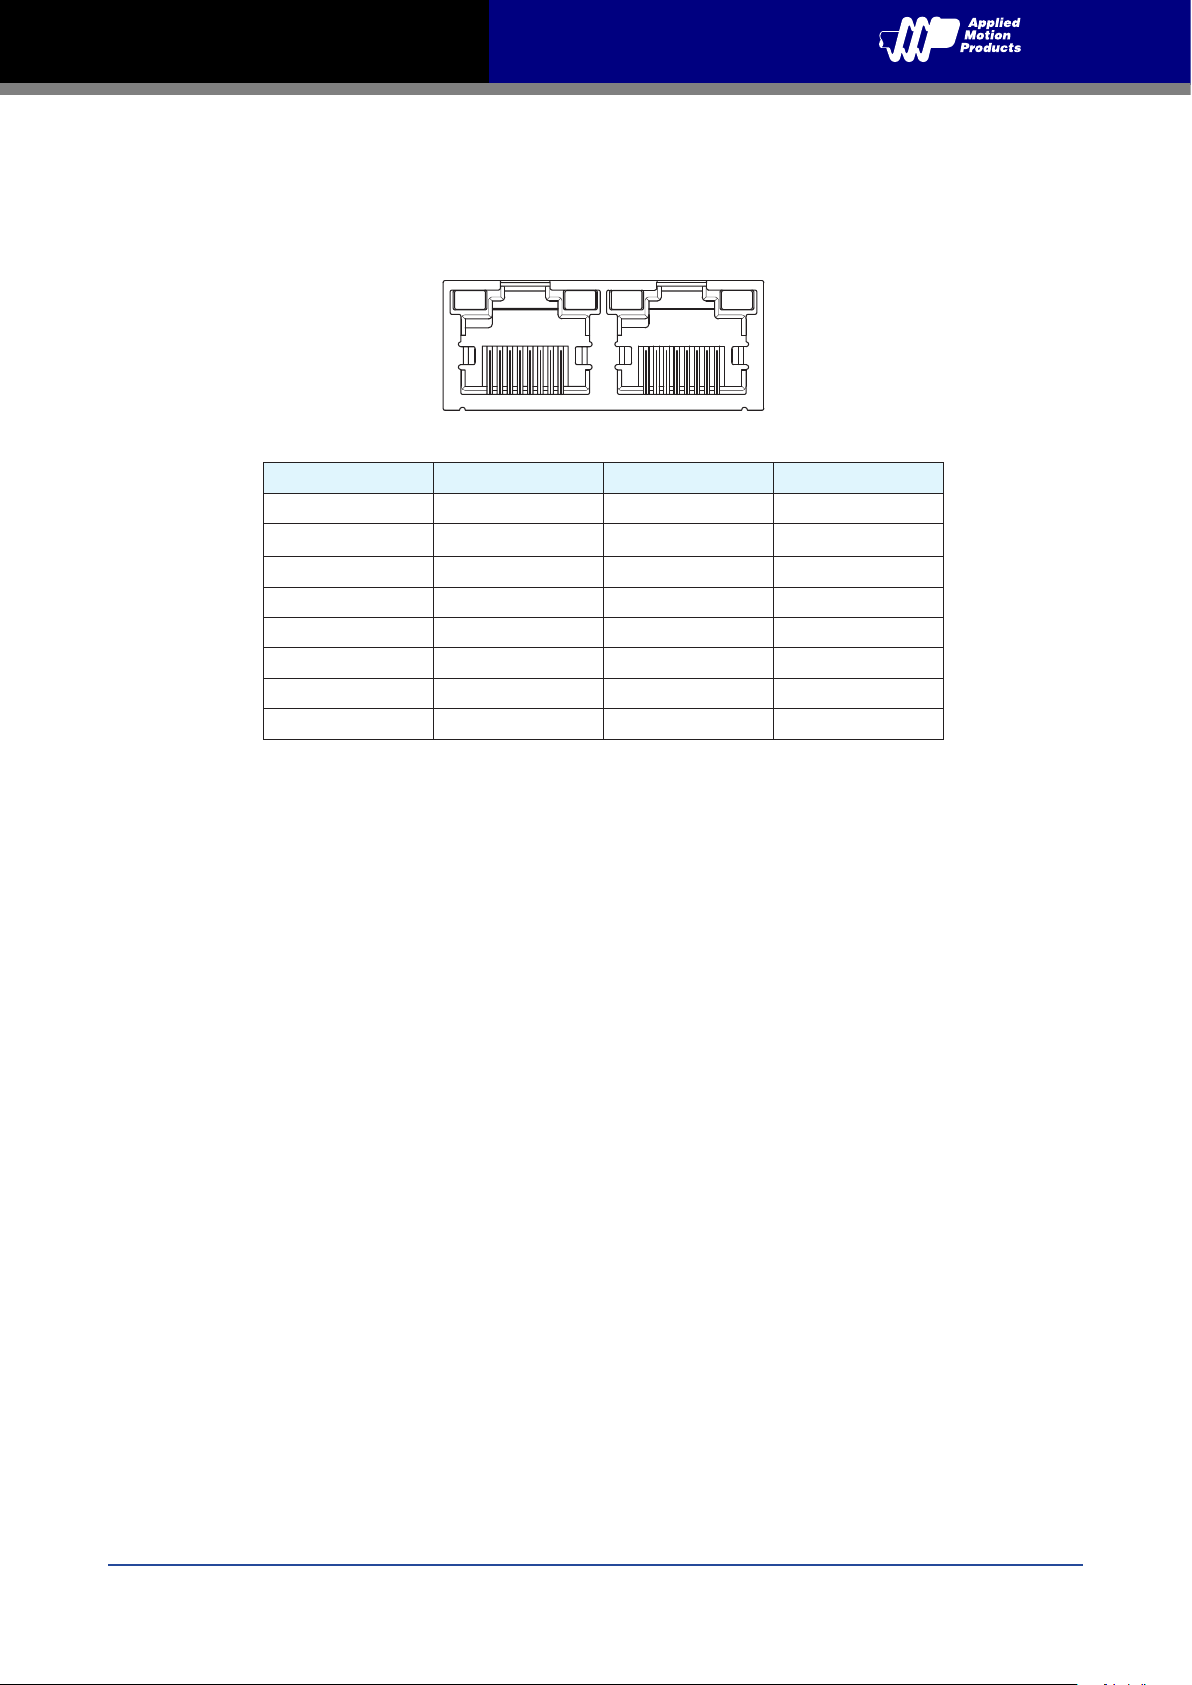
CANopen COM Port
COM1 COM2
PIN COM1 Signal COM2 Signal Color
1 CAN_H CAN_H Orange/White
2 CAN_L CAN_L Orange
3 GND GND Green/White
4 RS-232_TX NC Blue
5 RS-232_RX NC Blue/White
6 NC NC Green
7 GND GND Brown/Whitelv
8 GND GND Brown
1818
PC connection with RS-232 cable
Before using StepSERVO Quick Tuner for -C drive configuration, please connect COM1 on the driver to host PC by RS-232
programming cable.
CANopen network connection
Multiple -C model drive network can be built via dual CANopen communication port by daisy-chain cable or network cable
provided.
(NOTE: The CANopen port on the drive is isolated from internal circuitry of the drive. So the GND of each drive’s CANopen
port must be connected together. The first drive’s GND of the CANopen port must be connected to the GND of CANopen port
on the Controller)
11
Rev. 1.0
7/31/2019
Page 12
SSDC-R/C/IP Hardware Manual
2.4 Setting Node ID and baud rate
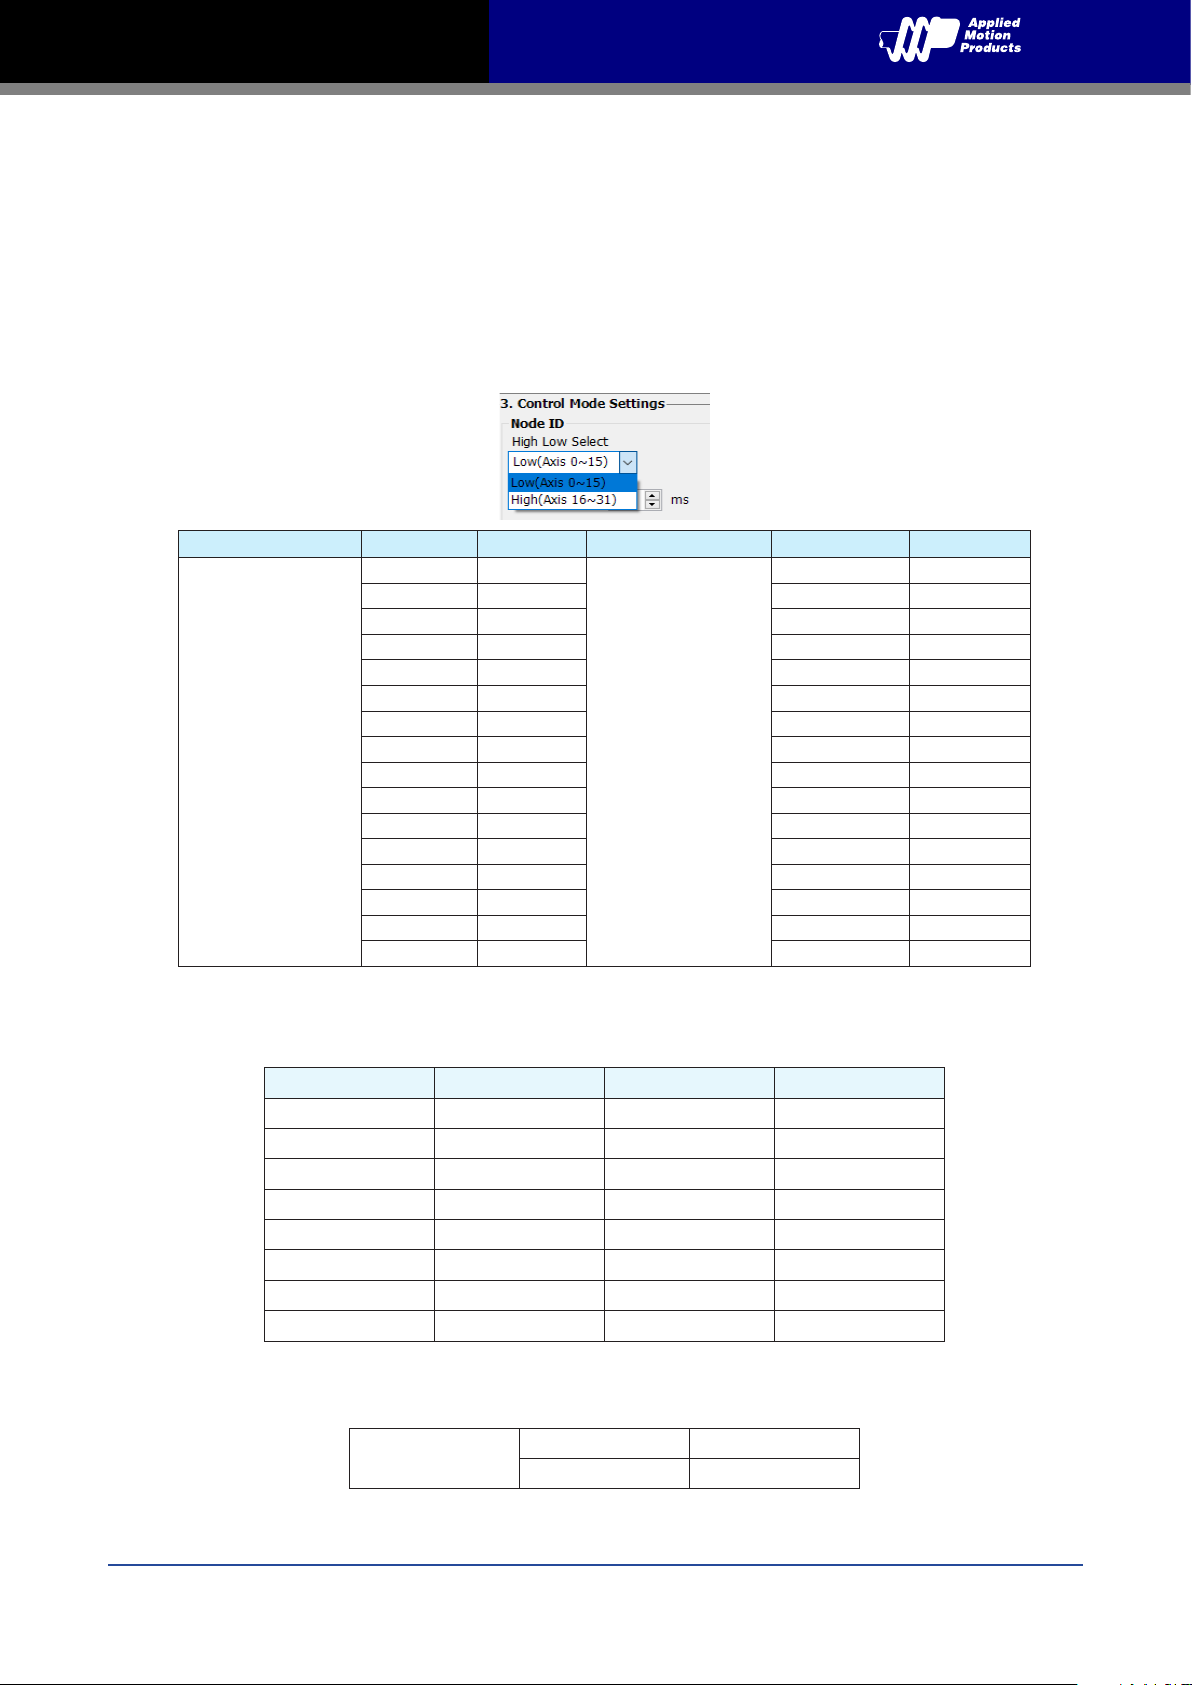
SSDC drives have one rotary switch and one piano switch to set the Node ID, baud rate and terminal resistor.
2.4.1 RS-485 Node ID and baud rate settings -R type
Set drive’s RS-485 Node ID by rotary switch S1, Set drive’s RS-485 baud rate and terminal resistor by piano switch S2
S1 is used to set drive’s RS-485 address, and th range is 0~F (0~15 in decimal). If you want the RS-485 Node ID range to
10~1F(16~31 in decimal), you need to configure it in StepSERVO Quick Tuner software.
Upper/Lower Address S1 position SCL address Upper/Lower Address S1 position SCL address
0 0
1 1 1 !
2 2 2 "
3 3 3 #
4 4 4 $
5 5 5 %
6 6 6 &
Lower(Axis 0~15)
7 7 7 '
8 8 8 (
9 9 9 )
A : A *
B ; B +
C < C ,
D = D E > E .
F ? F /
Upper(Axis 16~31)
S2 used to set the RS-485 baud rate, SW1, SW2 and SW3 are used to set the baud rate. SW4 is used to set the terminal
resistor.
0 @
RS-485/422 communication baud rate
SW1 SW2 SW3 Baud rate, bps
OFF OFF OFF 9600
OFF OFF ON 19200
OFF ON OFF 38400
OFF ON ON 57600
ON OFF OFF 115200
ON OFF ON /
ON ON OFF /
ON ON ON /
Terminal resistor
NOTE: Terminaation reisistor setting only needs to be on for the last drive in the network system for system more than 12 axis
SW4
Rev. 1.0
7/31/2019
OFF Disconnected
ON Connected
12
Page 13
SSDC-R/C/IP Hardware Manual
2.4.2 CANopen Node ID and baud rate settings(-C model)
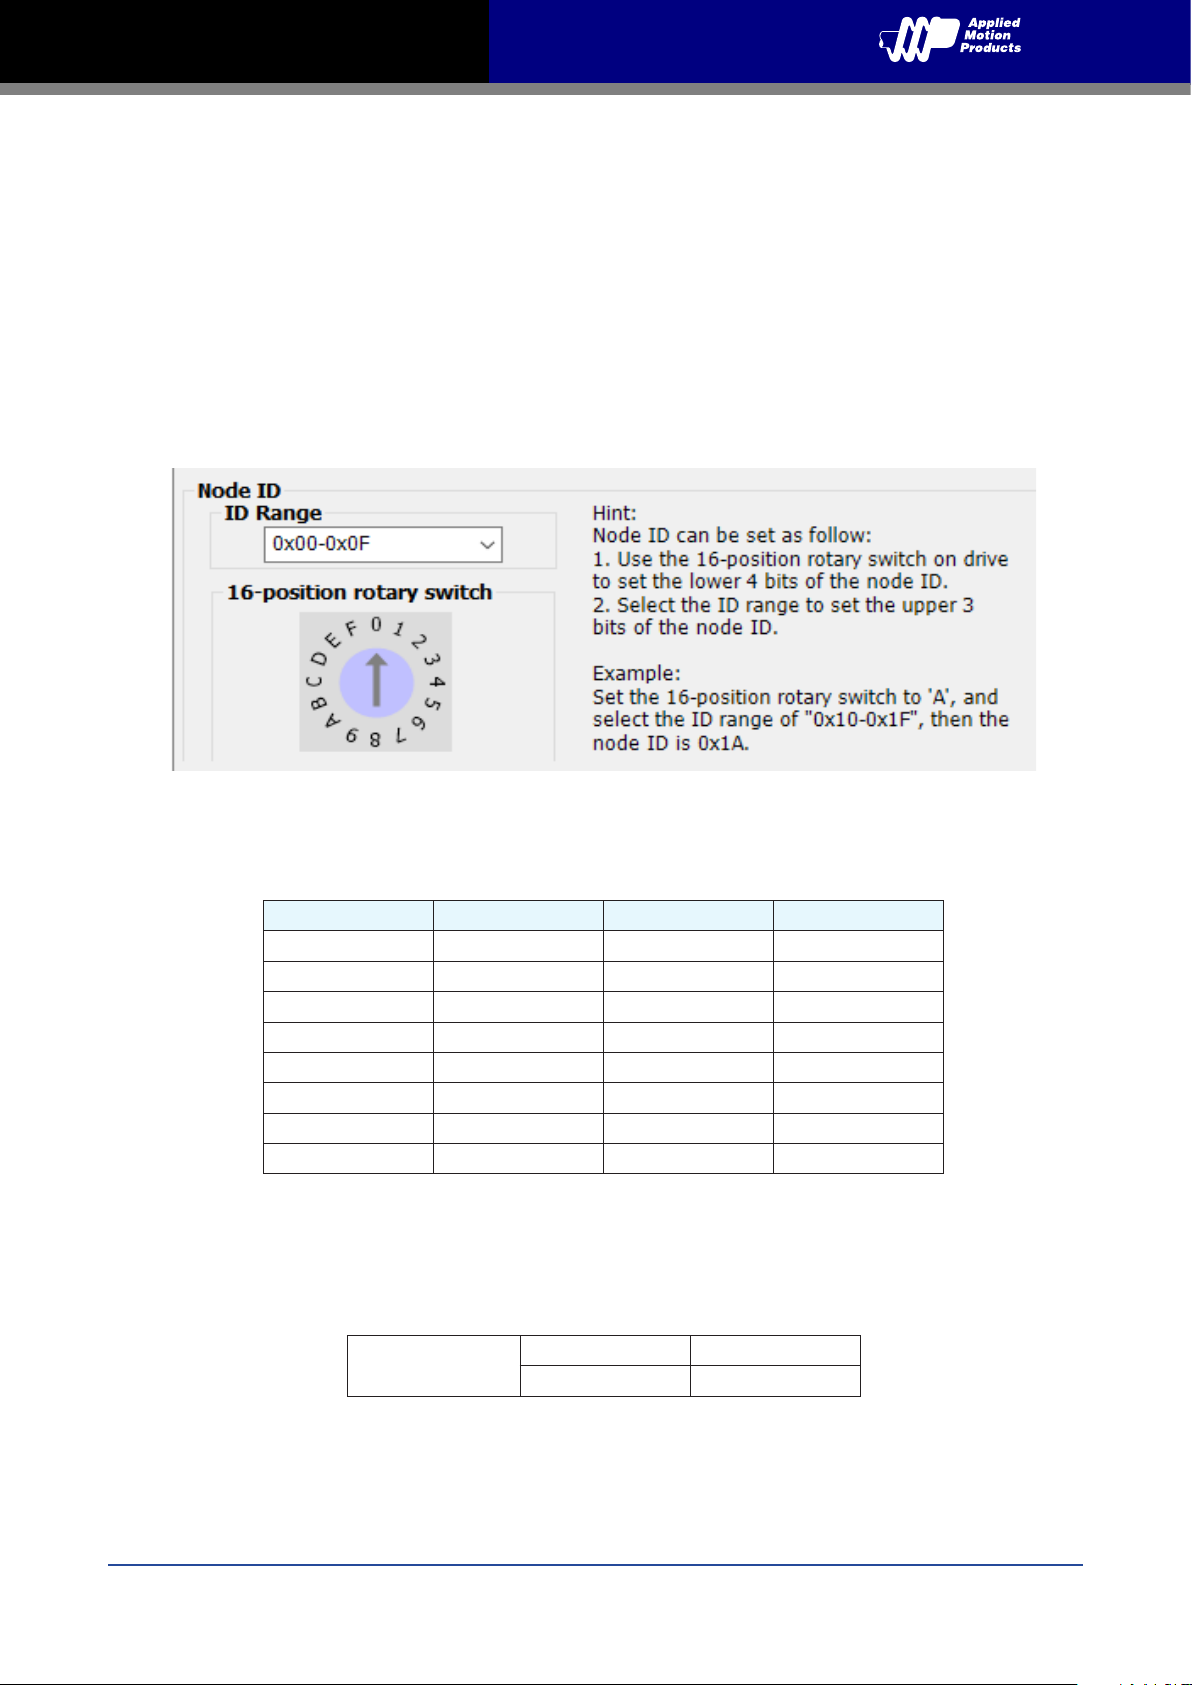
Set the lower 4 bits of drive’s CANopen Node ID by rotary switch S1
Set drive’s CANopen baud rate and terminal resistor by piano switch S2
Each node on a CANopen network must have a unique Node ID. Valid ranges for the Node ID are 0x01 through 0x7F
(1~127). Node ID 0x00 is reserved in accordance with CiA301. The Node ID is selected using rotary switches and software;
one sixteen position switch set the lower four bits (0~F) of node ID, while upper three bits of node ID are configured by
StepSERVO Quick Tuner software. Each time when Node ID is changed, a power cycle is required before the new Node ID is
valid.
Please refer to the CANopen manual for more information.
S2 used to set the CANopen baud rate, SW1, SW2 and SW3 are used to set the baud rate. SW4 is used to set the terminal
resistor.
CANopen communication baud rate
SW1 SW2 SW3 Baud rate目bps目
OFF OFF OFF 1M
OFF OFF ON 800K
OFF ON OFF 500K
OFF ON ON 250K
ON OFF OFF 125K
ON OFF ON 50K
ON ON OFF 20K
ON ON ON 12.5K
Terminal resistor
NOTE: Terminaation reisistor setting only needs to be on for the last drive in the network system for system.
SW4
OFF Disconnected
ON Connected
13
Rev. 1.0
7/31/2019
Page 14
SSDC-R/C/IP Hardware Manual
2.5 Choosing the Right COM Port
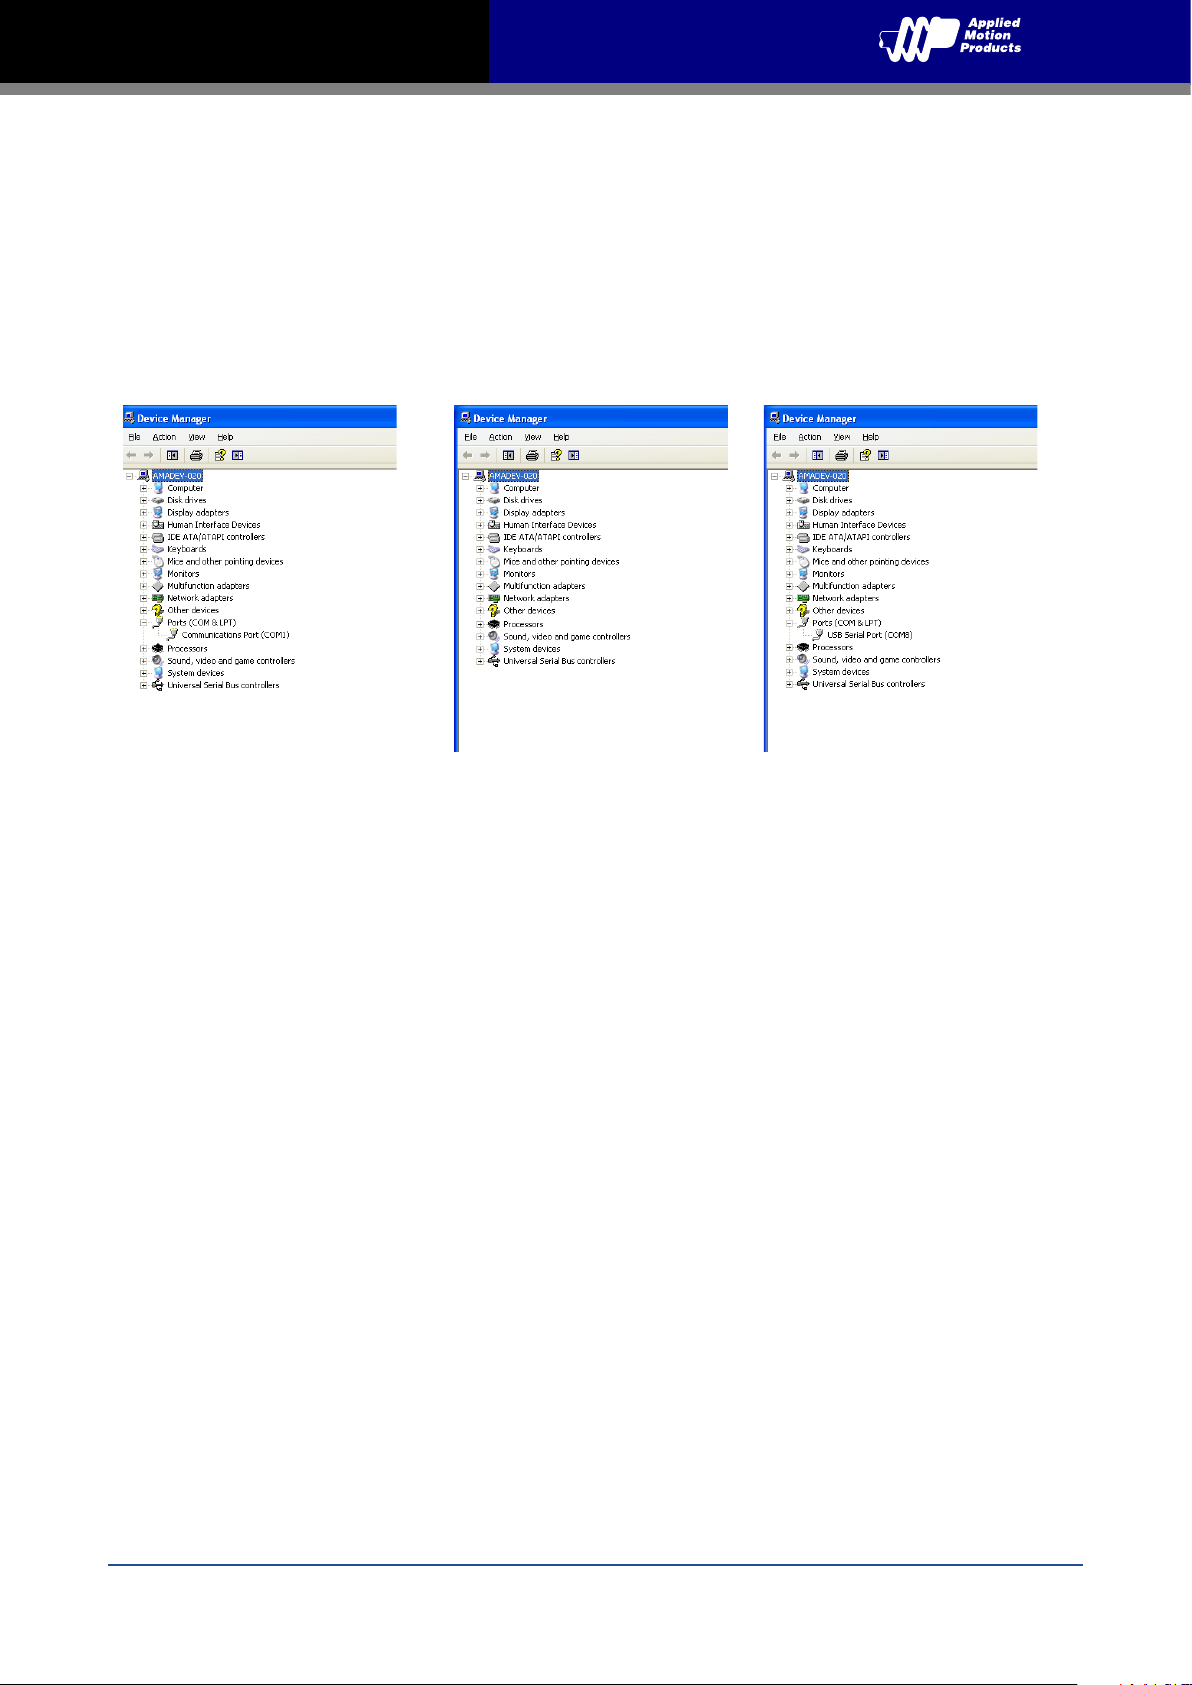
• Open the “Device Manager” on the PC. If the PC has an built-in RS-232 serial port, “Ports (COM & LPT)” (1) will be
displayed. Connect the PC and drive with the included RS-232 communication cable. Choose the connected COM(n)
port in the StepServo Quick Tuner software.
• If the PC does not have an RS-232 serial port, or has one but in using. A USB to RS-232 serial port adapter will be
needed. Open the “Device Manager” on the PC. There may or may not be a “Ports” selection. (2) Connect the adapter to
the PC, this USB adapter COM port should then be displayed. (3) Choose this new COM(n) port in the StepServo Quick
Tuner software.
Rev. 1.0
7/31/2019
14
Page 15
SSDC-R/C/IP Hardware Manual
2.6 Connecting the Drive to Your PC using Ethernet
The RJ45 connector of SSDC-D/IP is conformed to 100BASE-TX(100Mbps).
Please use the CAT5 or CAT5e(or higher class) net cable.
This process requires three steps:
• Physically connect the drive to your network (or directly to the PC)
• Set the drive’s IP address
• Set the appropriate networking properties on your PC.
Addresses, Subnets, and Ports
Every device on an Ethernet network must have a unique IP address. In order for two devices to communicate with each
other, they must both be connected to the network and they must have IP addresses that are on the same subnet. A subnet
is a logical division of a larger network. Members of one subnet are generally not able to communicate with members of
another unless they are connected through special network equipment (e.g. router). Subnets are defined by the choices of IP
addresses and subnet masks.
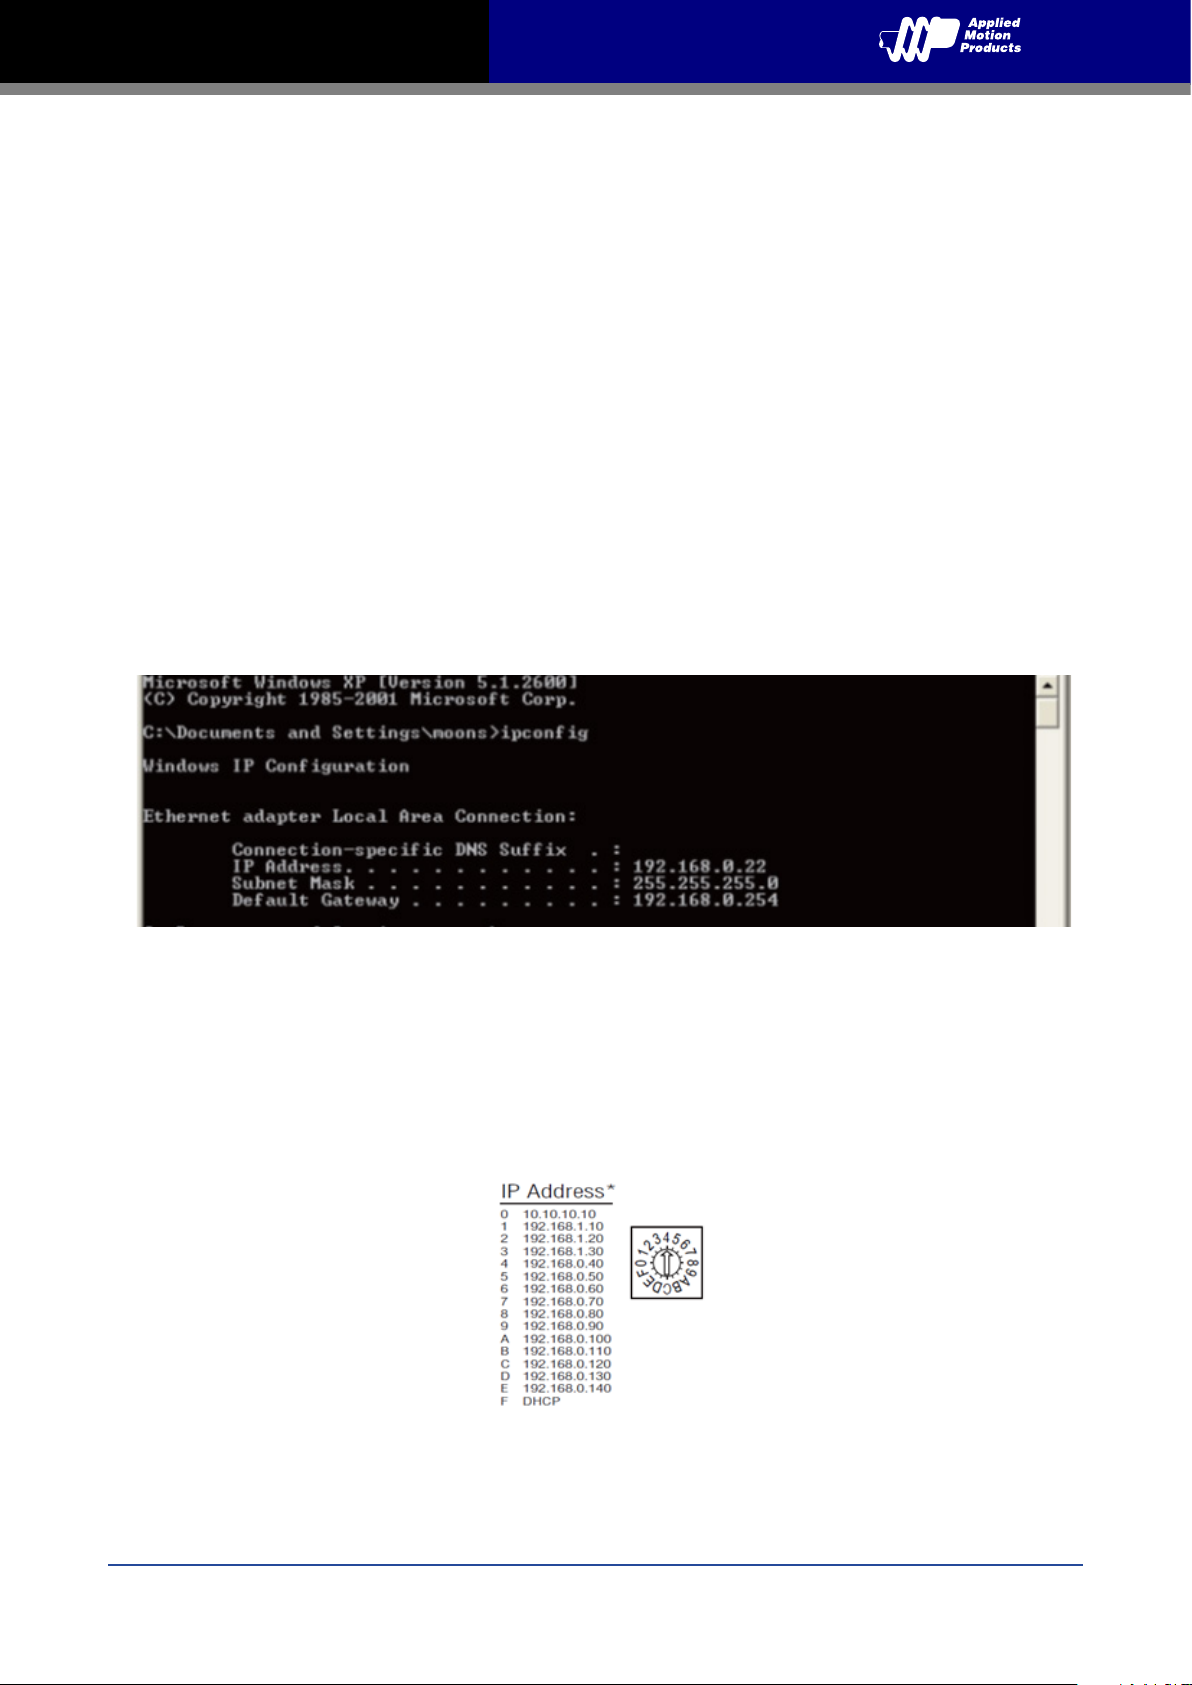
If you want to know the IP address and subnet mask of your PC, select Start…All Programs… Accessories…Command
Prompt. Then type “ipconfig” and press Enter. You should see something like this:
If your PC’s subnet mask is set to 255.255.255.0, a common setting known as a Class C subnet mask, then your machine can
only talk to another network device whose IP address matches yours in the first three octets. (The numbers between the dots
in an IP address are called octets.) For example, if your PC is on a Class C subnet and has an IP address of 192.168.0.20, it
can talk to a device at 192.168.0.40, but not one at 192.168.1.40. If you change your subnet mask to 255.255.0.0 (Class B)
you can talk to any device whose first two octets match yours. Be sure to ask your system administrator before doing this.
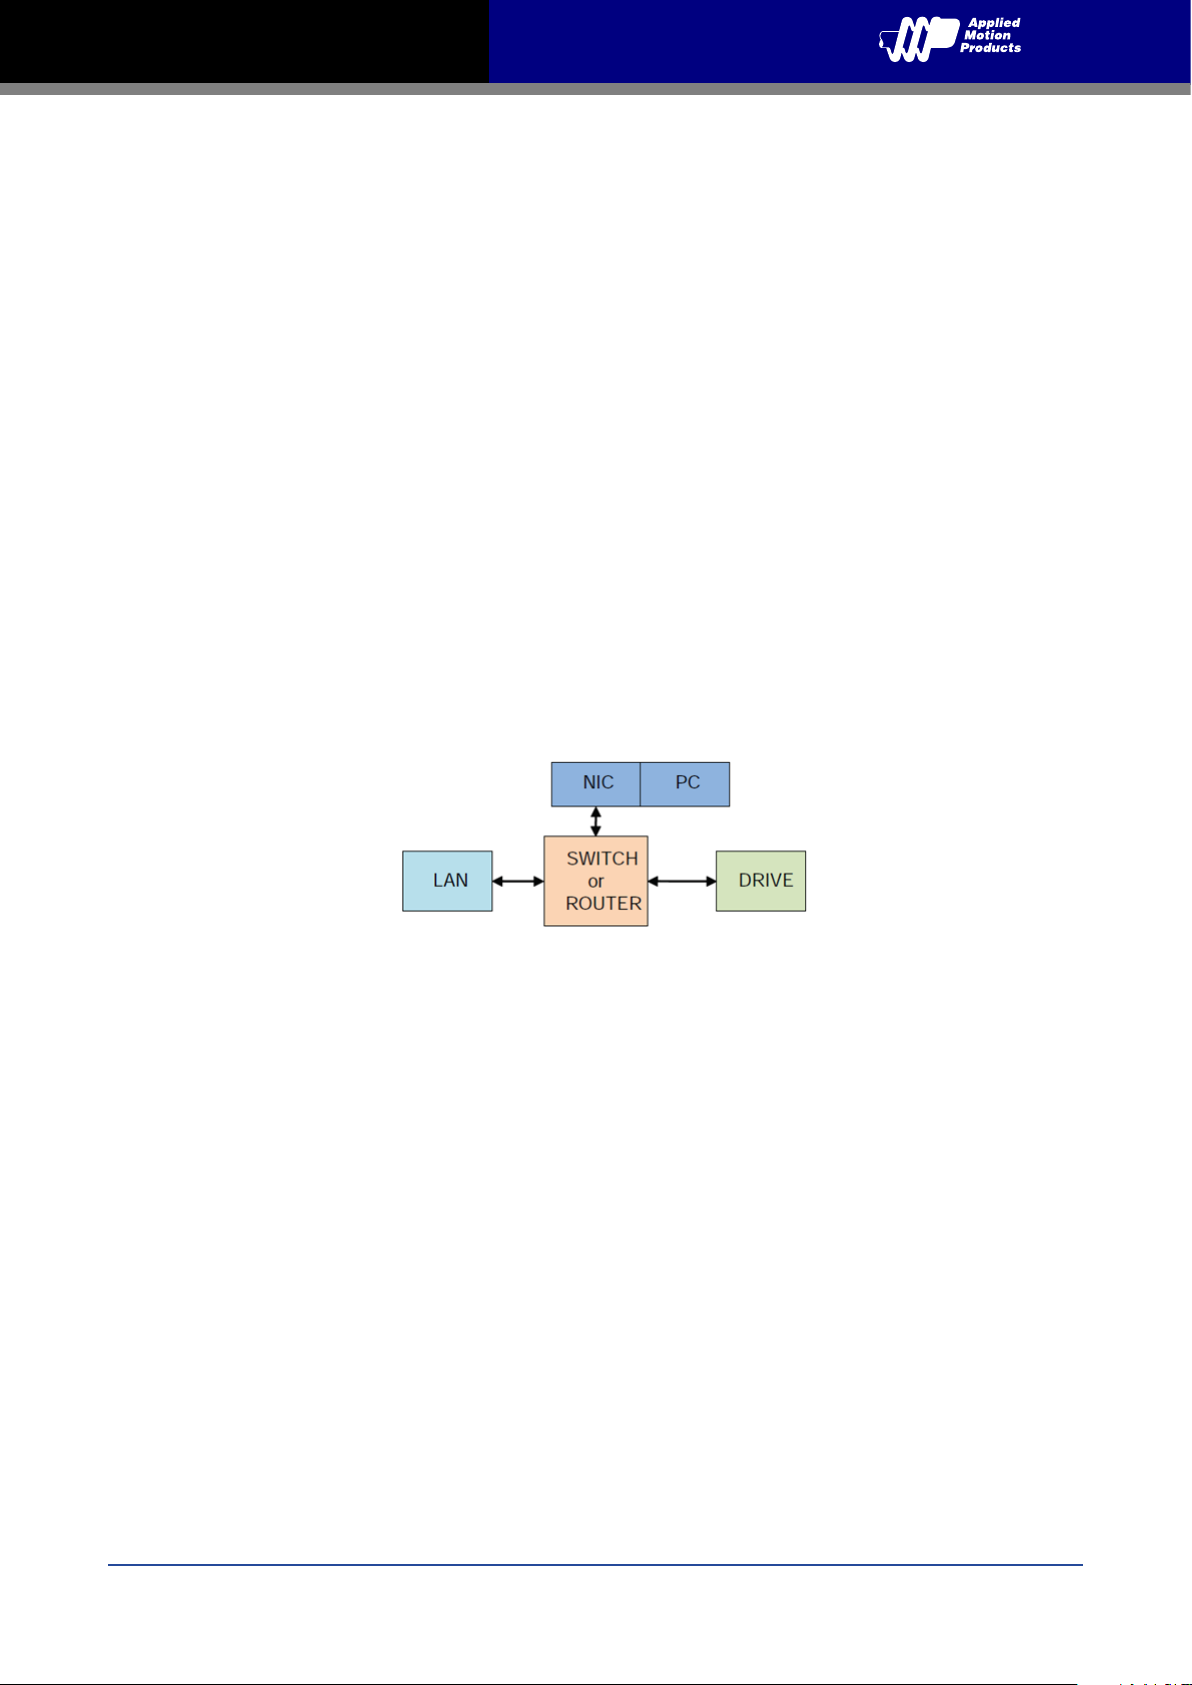
Your drive’s IP Address is stored internally in nonvolatile memory. There is a rotary switch to set the IP address. The default
addresses are in below table.
15
Rev. 1.0
7/31/2019
Page 16
SSDC-R/C/IP Hardware Manual
From the SW1 to SWE, you can redefine the IP address by StepSERVO Quick Tuner software. SW0 fixed address
“10.10.10.10”, it is a recovery address. If someone were to change the setting and not write it down or tell anyone then you
will not be able to communicate with your drive. The only way to “recover” it is to apply power to the drive with the network
cable unplugged.
One of the great features of Ethernet is the ability for many applications to share the network at the same time. Ports are
used to direct traffic to the right application once it gets to the right IP address. The UDP eSCL port in our drives is 7775. To
send and receive commands using TCP, use port number 7776. You’ll need to know this when you begin to write your own
application. You will also need to choose an open (unused) port number for your application. Our drive doesn’t care what
that is; when the first command is sent to the drive, the drive will make note of the IP address and port number from which it
originated and direct any responses there. The drive will also refuse any traffic from other IP addresses that is headed for the
eSCL port. The first application to talk to a drive “owns” the drive. This lock is only reset when the drive powers down.
One final note: Ethernet communication can use one or both of two “transport protocols”: UDP and TCP. eSCL commands
can be sent and received using either protocol. UDP is simpler and more efficient than TCP, but TCP is more reliable on large
or very busy networks where UDP packets might occasionally be dropped.
Option 1: Connect a Drive to Your Local Area Network
If you have a spare port on a switch or router and if you are able to set your drive to an IP address that is compatible with
your network, and not used by anything else, this is a simple way to get connected. This technique also allows you to connect
multiple drives to your PC. If you are on a corporate network, please check with your system administrator before connecting
anything new to the network. He or she should be able assign you a suitable address and help you get going.
If the default address is not acceptable for you network, you can enter a new IP address using StepSERVO Quick Tuner. If your
PC address is not in 192.168.1. subnet, you will have to change your subnet mask to 255.255.0.0 in order to talk to your
drive. To change your subnet mask:
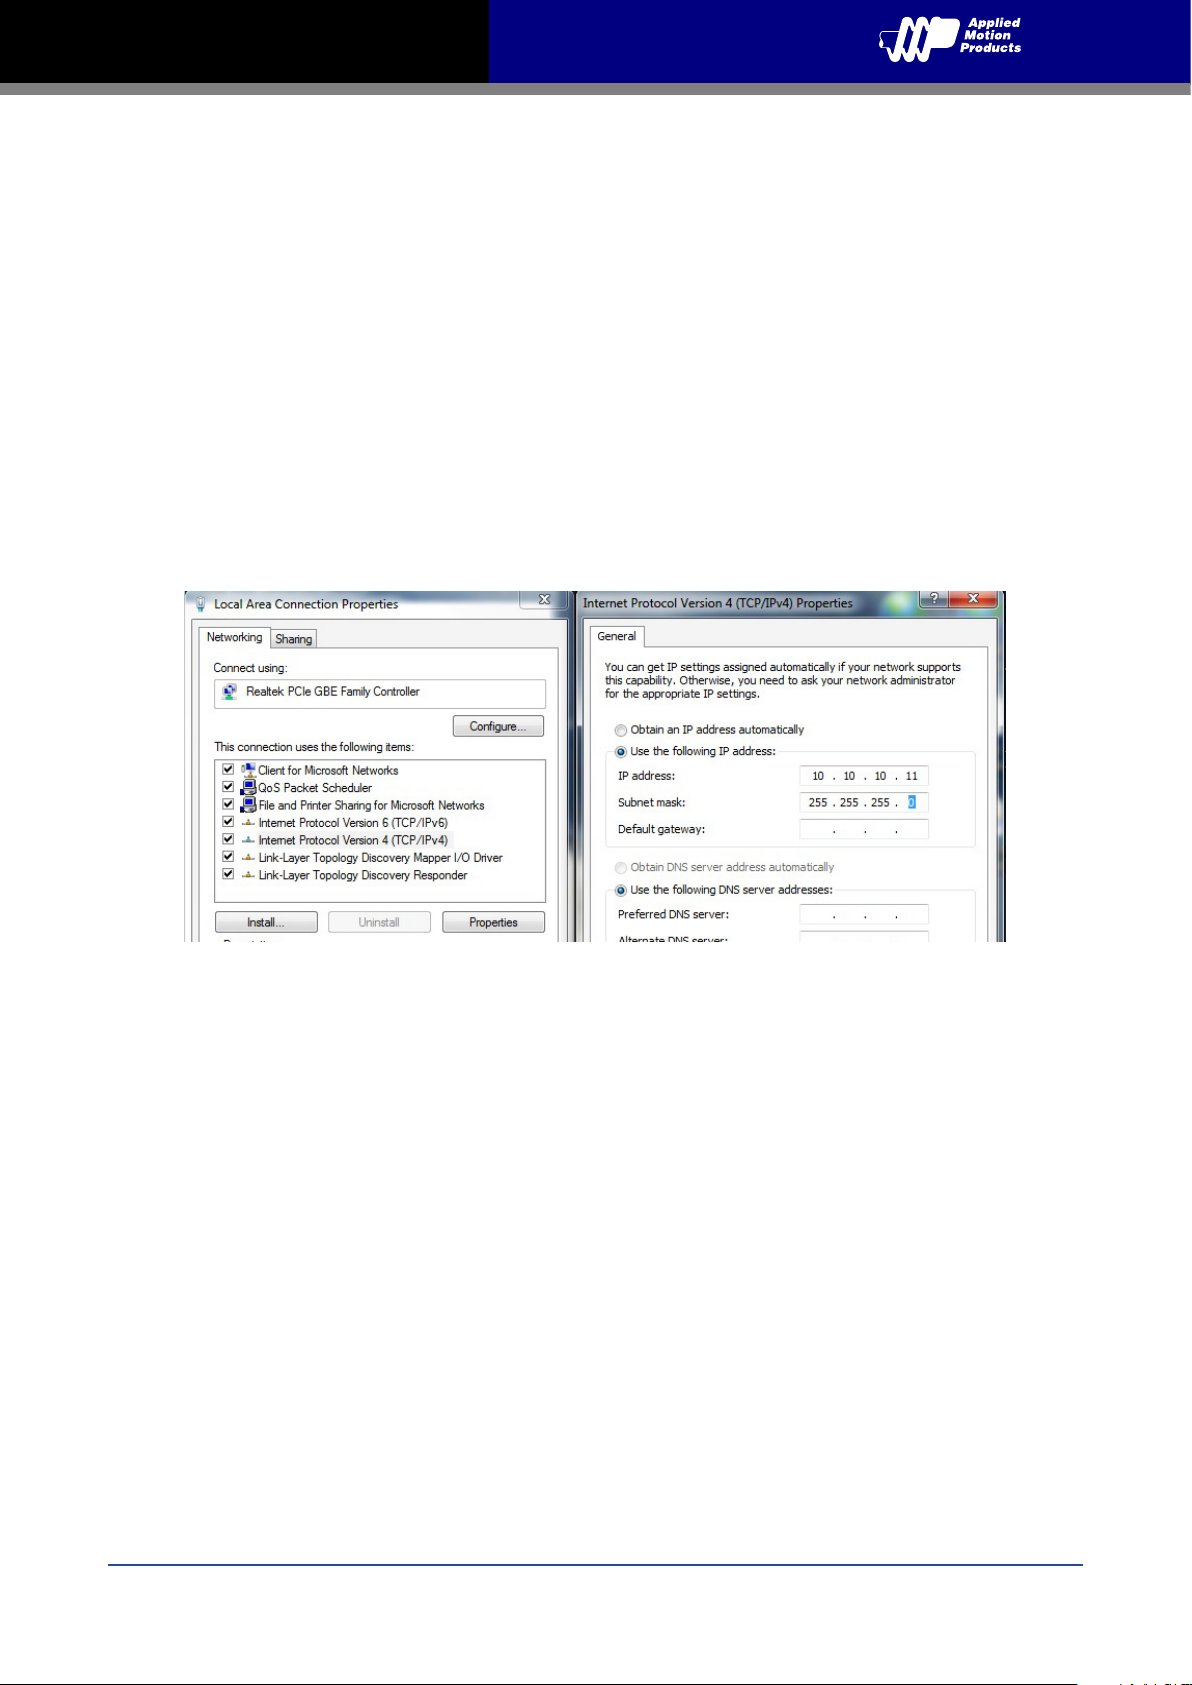
1. On Windows XP, right click on “My Network Places” and select properties. On Windows 7, click Computer. Scroll down the
left pane until you see “Network”. Right click and select properties. Select “Change adapter settings”
2. You should see an icon for your network interface card (NIC). Right click and select properties.
3. Scroll down until you see “Internet Properties (TCP/IP)”. Select this item and click the Properties button. On Windows 7
and Vista, look for “(TCP/IPv4)”
4. If the option “Obtain an IP address automatically” is selected, your PC is getting an IP address and a subnet mask from the
DHCP server. Please cancel this dialog.
5. If the option “Use the following IP address” is selected, life is good. Change the subnet mask to “255.255.0.0” and click
OK.
Rev. 1.0
7/31/2019
16
Page 17
SSDC-R/C/IP Hardware Manual
Option 2: Connect a Drive Directly to Your PC
1. Connect one end of a CAT5e STP cable into the LAN card (NIC) on your PC and the other to the drive.
You don’t need a special “crossover cable”; the drive will automatically detect the direct connection and make the necessary
physical layer changes.
2. The default IP address is “10.10.10.10”.
3. To set the IP address of your PC:
a. On Windows XP, right click on “My Network Places” and select properties.
b. On Windows 7, click Computer. Scroll down the left pane until you see “Network”. Right click and select
properties. Select “Change adapter settings”
4. You should see an icon for your network interface card (NIC). Right click and select properties.
a. Scroll down until you see “Internet Properties (TCP/IP)”. Select this item and click the Properties button.
b. On Windows 7 and Vista, look for “(TCP/IPv4)”
5. Select the option “Use the following IP address”. Then enter the address “10.10.10.10”. This will give your PC an IP
address that is on the same subnet as the drive. Windows will know to direct any traffic intended for the drive’s IP address
to this interface card.
6. Next, enter the subnet mask as “255.255.255.0”.
7. Be sure to leave “Default gateway” blank. This will prevent your PC from looking for a router on this subnet.
8. Because you are connected directly to the drive, anytime the drive is not powered on, your PC will annoy you with a
small message bubble in the corner of your screen saying “The network cable is unplugged.”
17
Rev. 1.0
7/31/2019
Page 18
SSDC-R/C/IP Hardware Manual
Option 3: Use Two Network Interface Cards (NICs)
This technique allows you to keep your PC connected to your LAN, but keeps the drive off the LAN, preventing possible IP
conflicts or excessive traffic.
1. If you use a desktop PC and have a spare card slot, install a second NIC and connect it directly to the drive using a CAT5e
cable. You don’t need a special “crossover cable”; the drive will automatically detect the direct connection and make the
necessary physical layer changes.
2. If you use a laptop and only connect to your LAN using wireless networking, you can use the built-in RJ45 Ethernet
connection as your second NIC.
3. The default IP address is “10.10.10.10”.
4. To set the IP address of the second NIC:
a. On Windows XP, right click on “My Network Places” and select properties.
b. On Windows 7, click Computer. Scroll down the left pane until you see “Network”. Right click and select properties.
Select “Change adapter settings”
5. You should see an icon for your newly instated NIC. Right click again and select properties.
a. Scroll down until you see “Internet Properties (TCP/IP)”. Select this item and click the Properties button.
b. On Windows 7 and Vista, look for “(TCP/IPv4)”
6. Select the option “Use the following IP address”. Then enter the address “10.10.10.10”. This will give your PC an IP address
that is on the same subnet as the drive. Windows will know to direct any traffic intended for the drive’s IP address to this
interface card.
7. Next, enter the subnet mask as “255.255.255.0”. Be sure to leave “Default gateway” blank. This will prevent your PC from
looking for a router on this subnet.
8. Because you are connected directly to the drive, anytime the drive is not powered on your PC will annoy you with a small
message bubble in the corner of your screen saying “The network cable is unplugged.”
Rev. 1.0
7/31/2019
18
Page 19
SSDC-R/C/IP Hardware Manual
2.7 Connecting the Power Supply
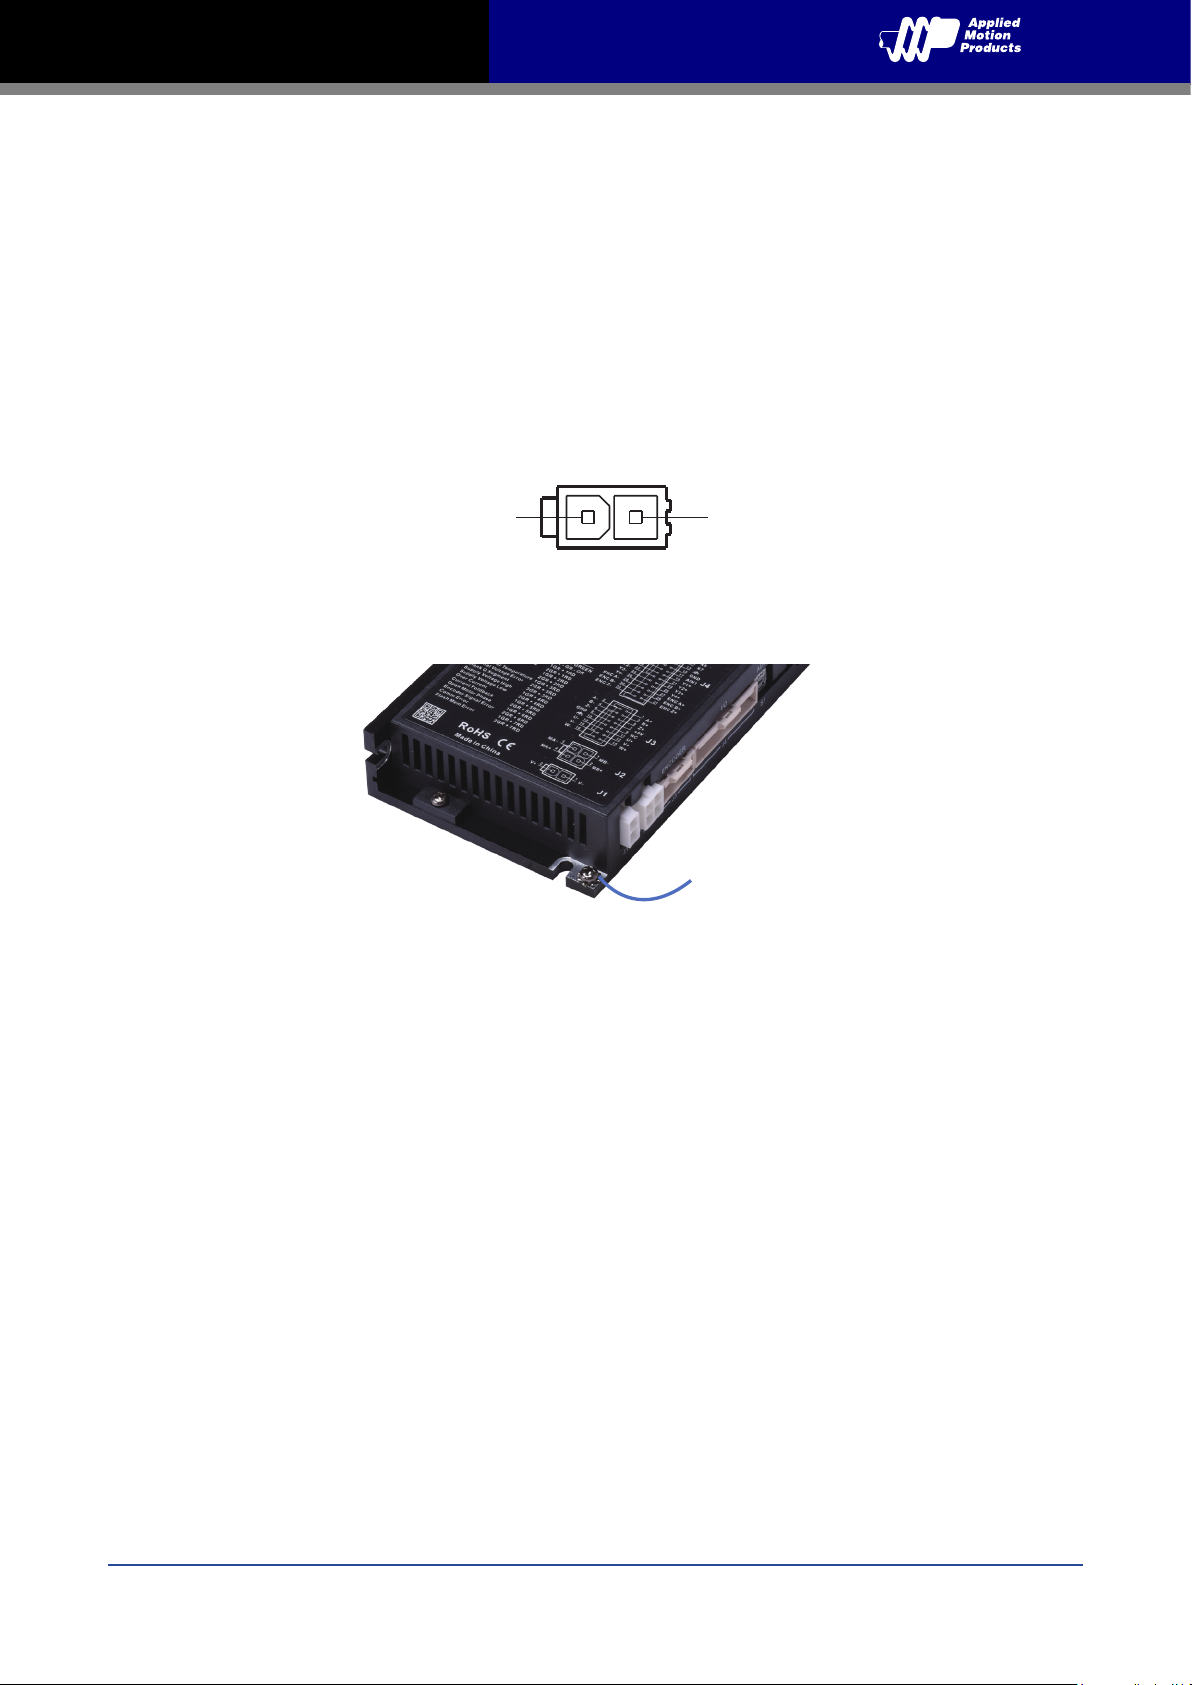
The SSDC series StepSERVO drive and motor are shipped with a power cable, 2 meters long. Connect the red wire to the
positive of the power supply. Connect the black wire to the negative of the power supply. Plug the cable into the power
connector of the drive.
(NOTE: DO NOT reverse the wires. Reversing the connection may open the internal fuse on the drive and void the warranty.)
SSDC03: 12 – 48VDC
SSDC06: 24 – 70VDC
SSDC10: 24 – 70VDC
J1
VV++
22
11
VV
--
Power Connector
Connect the chassis to the earth ground through the grounding screws.
To Earth Ground
The section entitled “Choosing a Power Supply” will help you to select a right power supply.
19
Rev. 1.0
7/31/2019
Page 20
SSDC-R/C/IP Hardware Manual
2.8 Choosing a Power Supply
The main considerations when choosing a power supply are the voltage and current requirements for the application.
2.8.1 Voltage
The SSDC drive is designed to give optimum performance between 24 and 48 Volts DC. Choosing the voltage depends on
the performance needed and motor/drive heating that is acceptable and/or does not cause a drive over-temperature. Higher
voltages will give higher speed performance but will cause the SSDC driver to produce higher temperatures. Using power
supplies with voltage outputs that are near the drive maximum may significantly reduce the operational duty-cycle.
SSDC03
For the SSDC03 drive, the extended range of operation can be as low as 11 VDC minimum to as high as 53 VDC maximum.
When operating below 11 VDC, the power supply input may require larger capacitance to prevent under-voltage and internalsupply alarms. Current spikes may make supply readings erratic. The supply input cannot go below 11 VDC for reliable
operation. This will not fault the drive. Absolute maximum power supply input is 53 VDC at which point an over-voltage
alarm and fault will occur. When using a power supply that is regulated and is near the drive maximum voltage of 53 VDC, a
voltage clamp may be required to prevent over-voltage when regeneration occurs. When using an unregulated power supply,
make sure the no-load voltage of the supply does not exceed the drive’s maximum input voltage of 53 VDC.
SSDC06/10
For the SSDC06/10 drive, the extended range of operation can be as low as 18 VDC minimum to as high as 75 VDC
maximum. When operating below 18 VDC, the power supply input may require larger capacitance to prevent under-voltage
and internal-supply alarms. Current spikes may make supply readings erratic. The supply input cannot go below 18 VDC for
reliable operation. This will not fault the drive. Absolute maximum power supply input is 75 VDC at which point an overvoltage alarm and fault will occur. When using a power supply that is regulated and is near the drive maximum voltage of 75
VDC, a voltage clamp may be required to prevent over-voltage when regeneration occurs. When using an unregulated power
supply, make sure the no-load voltage of the supply does not exceed the drive’s maximum input voltage of 75 VDC.
Rev. 1.0
7/31/2019
20
Page 21
SSDC-R/C/IP Hardware Manual
HT11-SS1DM_ 24V Power
0.0
0.2
0.4
0.6
0.8
1.0
1.2
0
20
40
60
80
100
0 10 20 30 40 50
Torque(mN.m)
Speed(RPS)
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
HT11-SS2DM_ 24V Power
0.0
0.2
0.4
0.6
0.8
1.0
1.2
0
20
40
60
80
100
0 10 20 30 40 50
Torque(mN.m)
Speed(RPS)
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
HT11-SS3DM_ 24V Power
0.0
0.2
0.4
0.6
0.8
1.0
1.2
0
30
60
90
120
150
0 10 20 30 40 50
Torque(mN.m)
Speed(RPS)
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
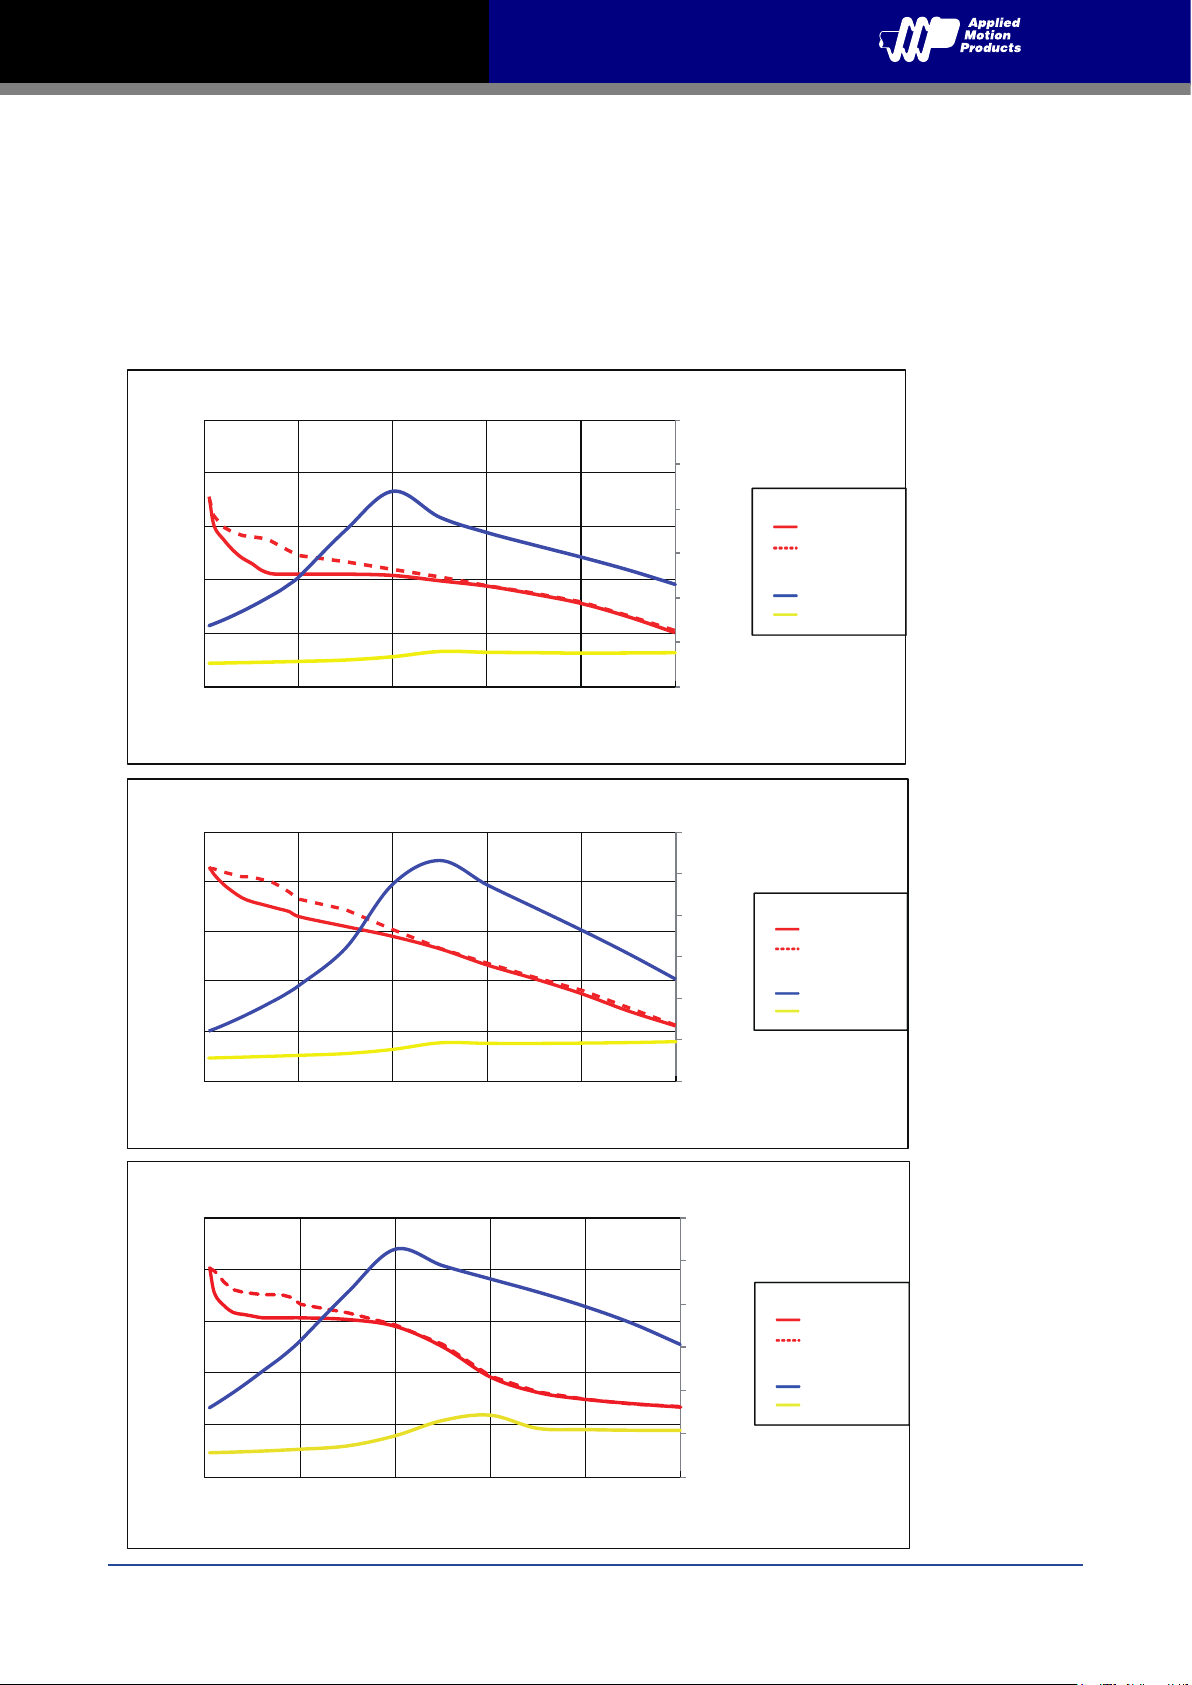
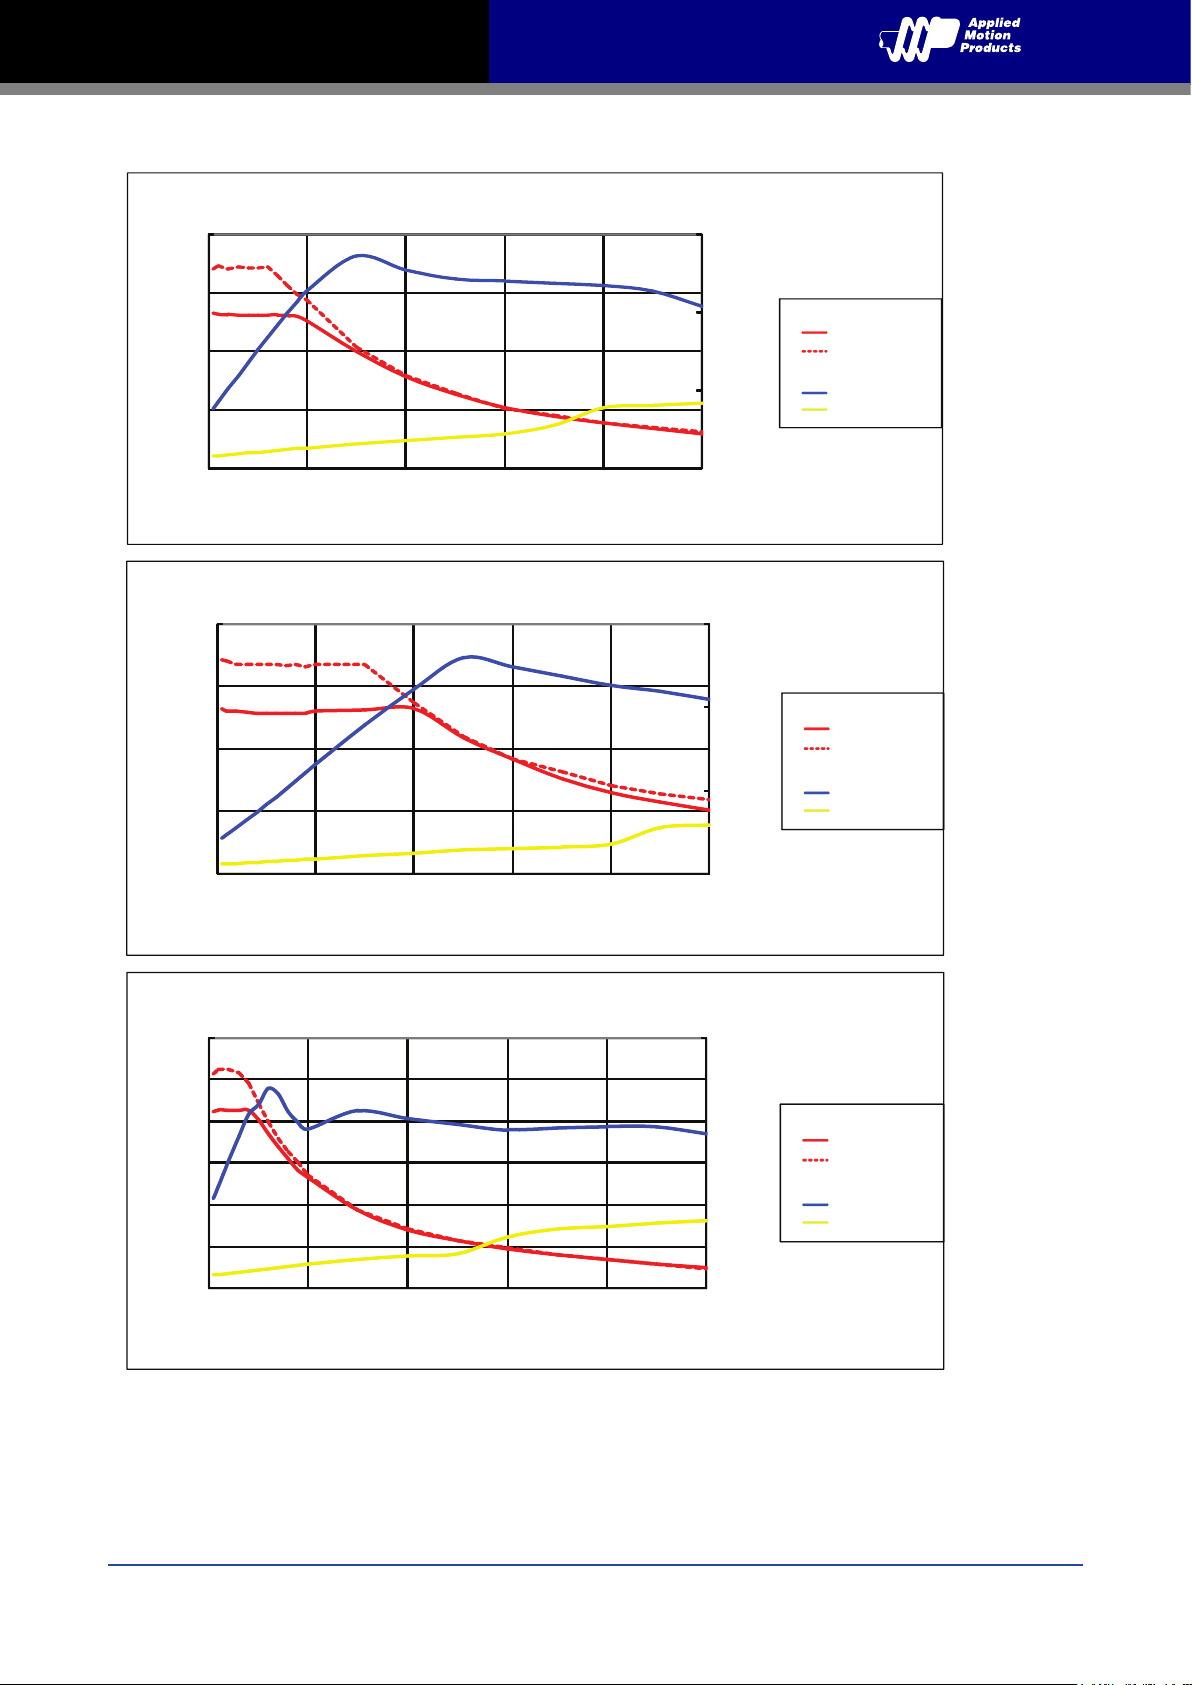
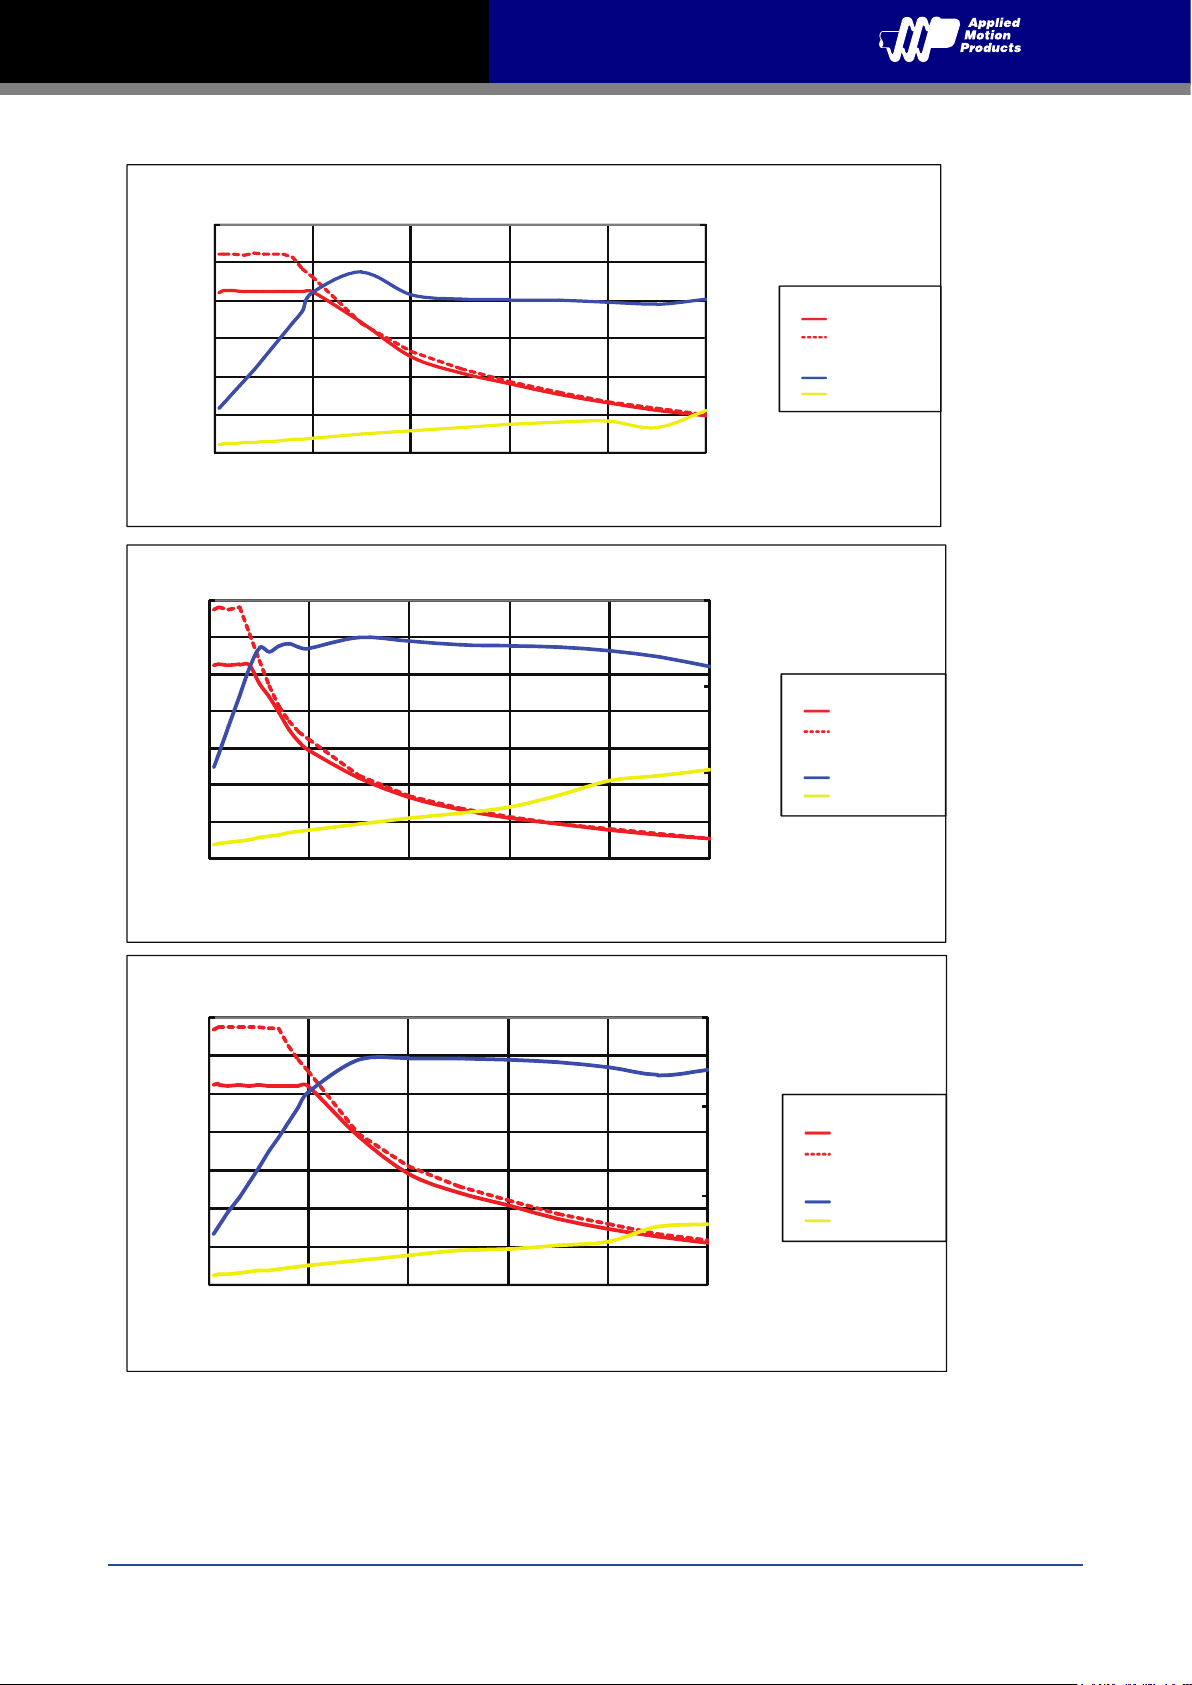
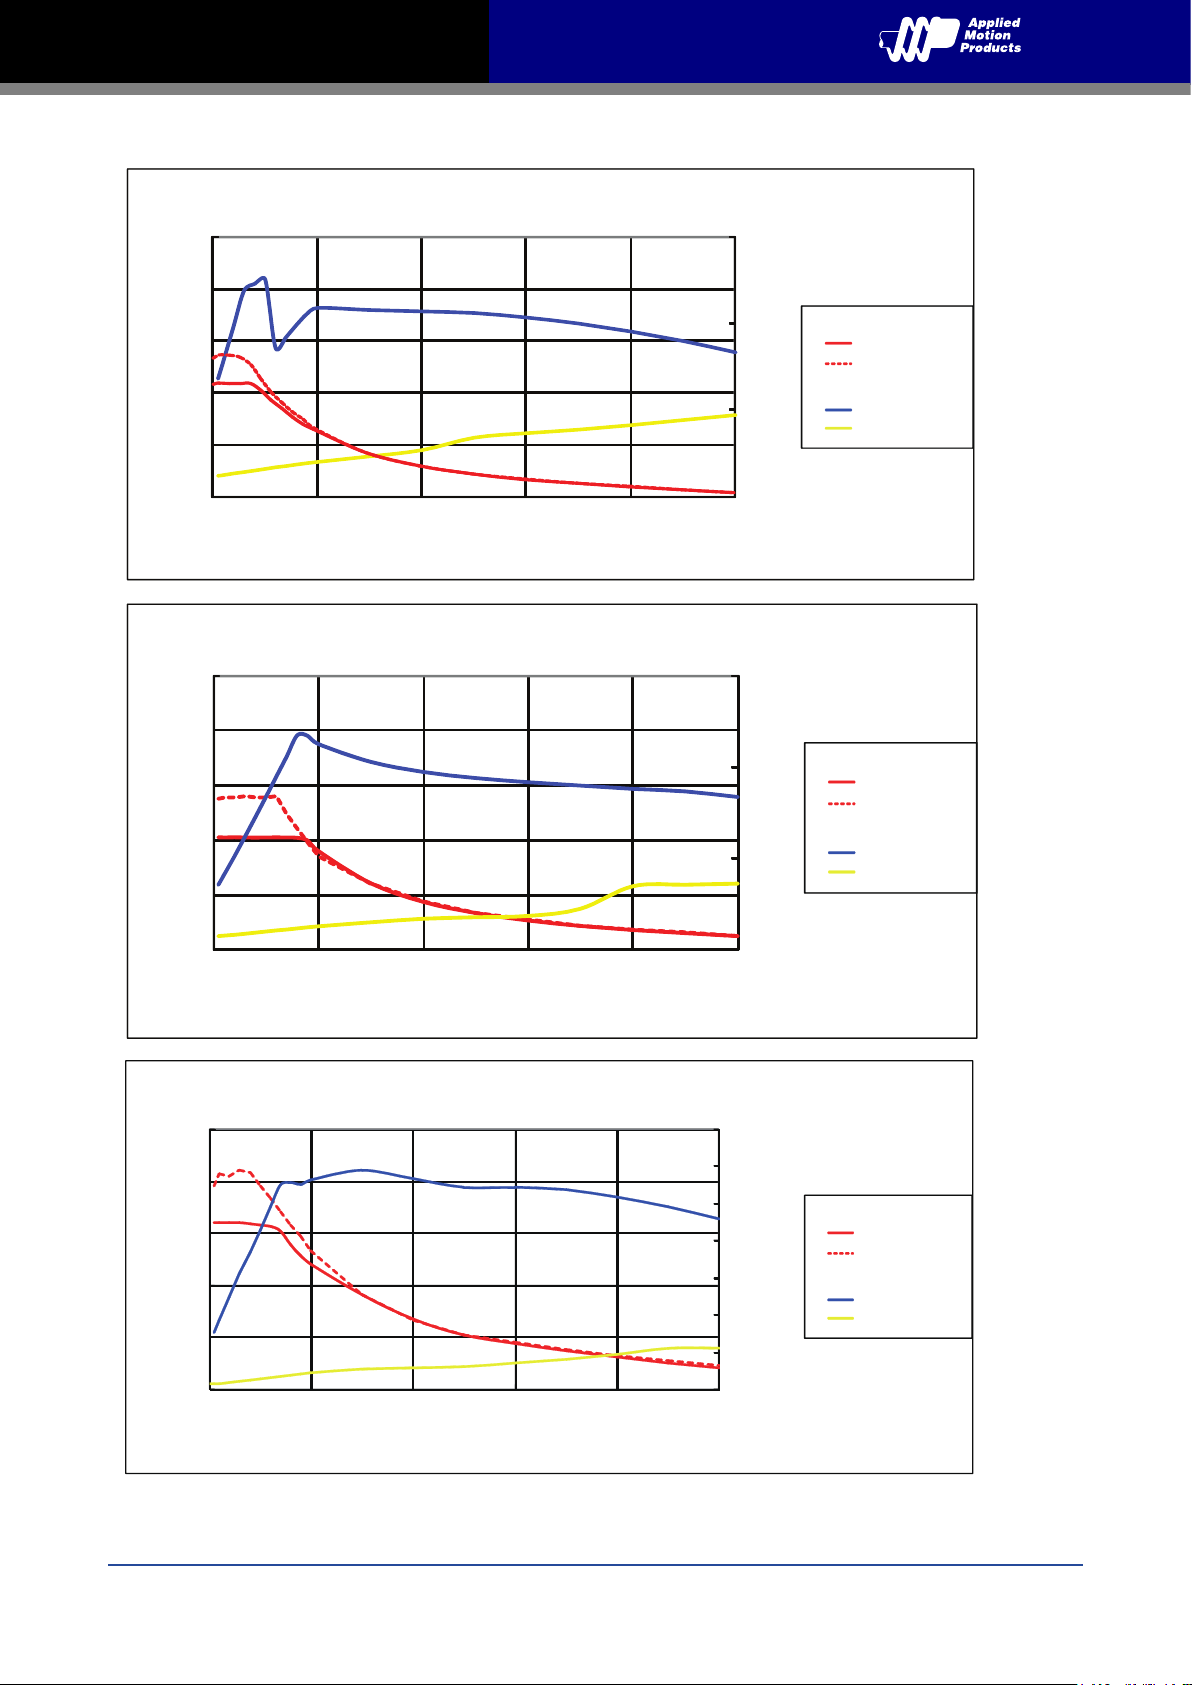
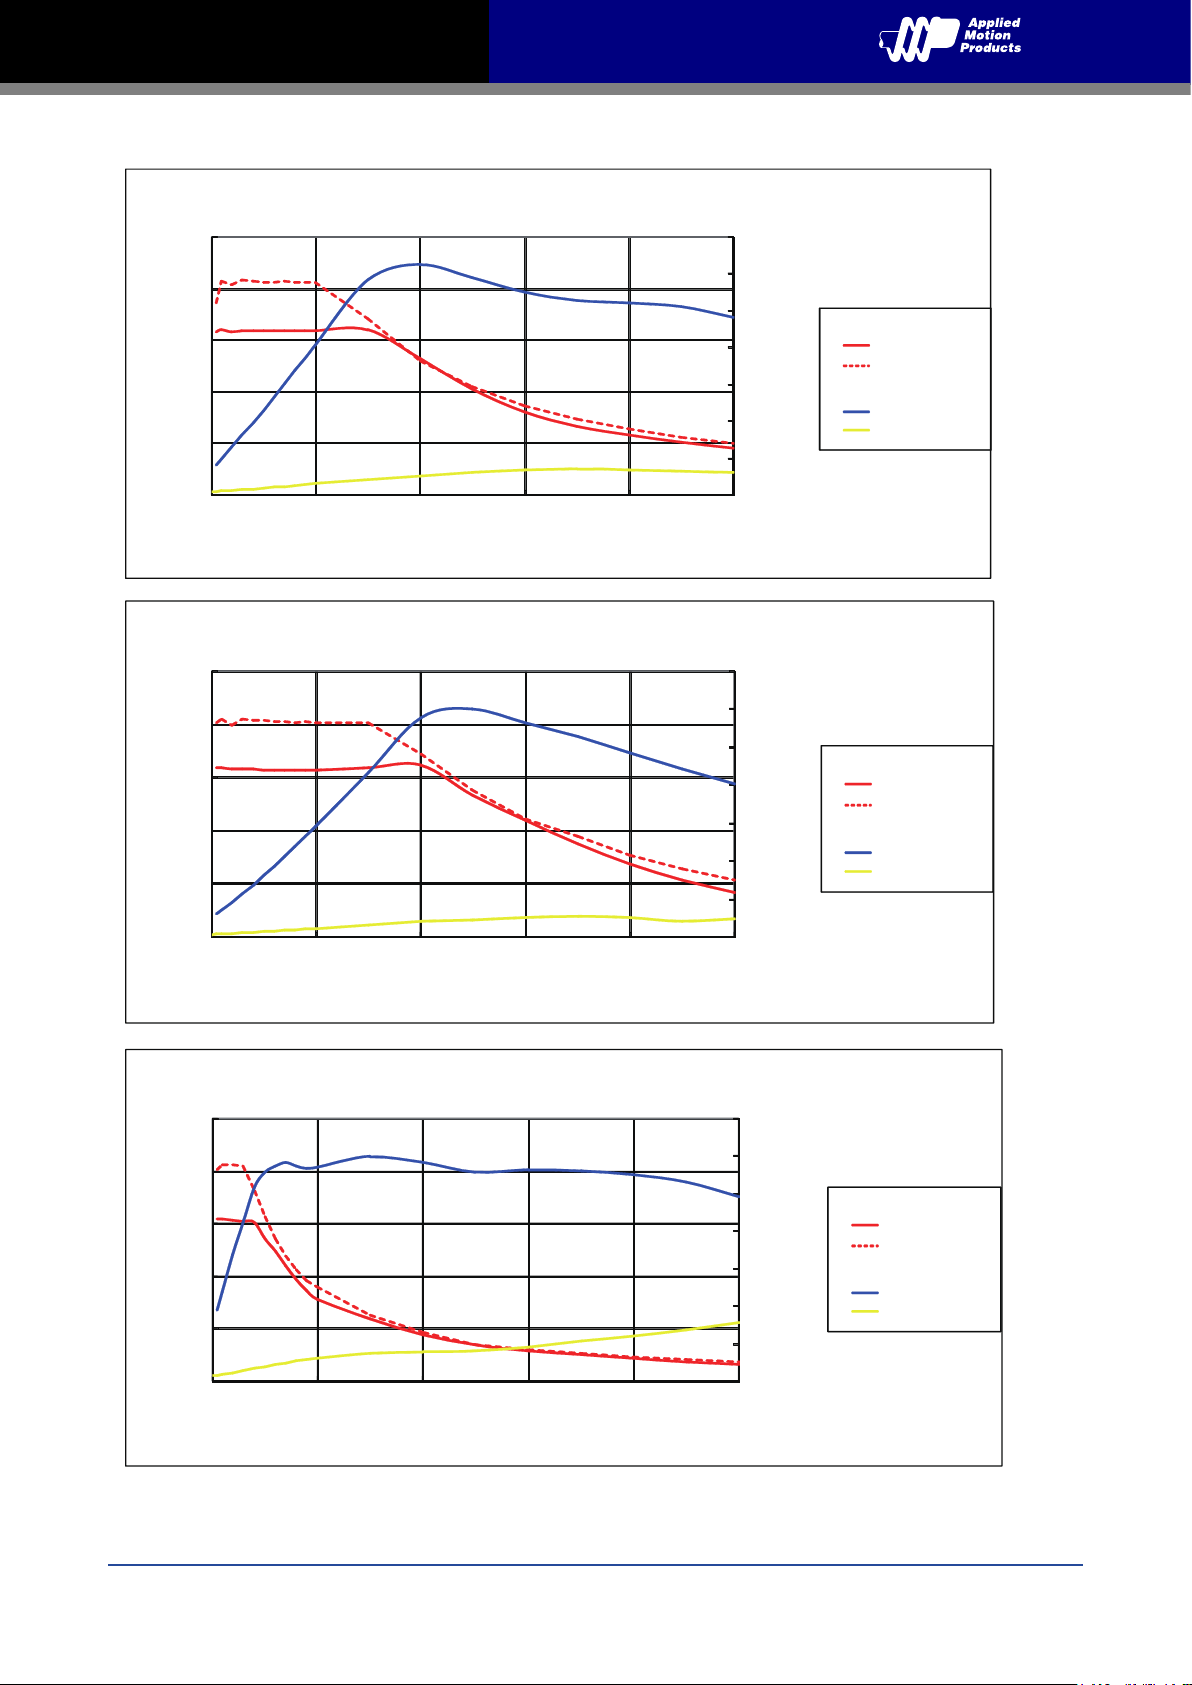
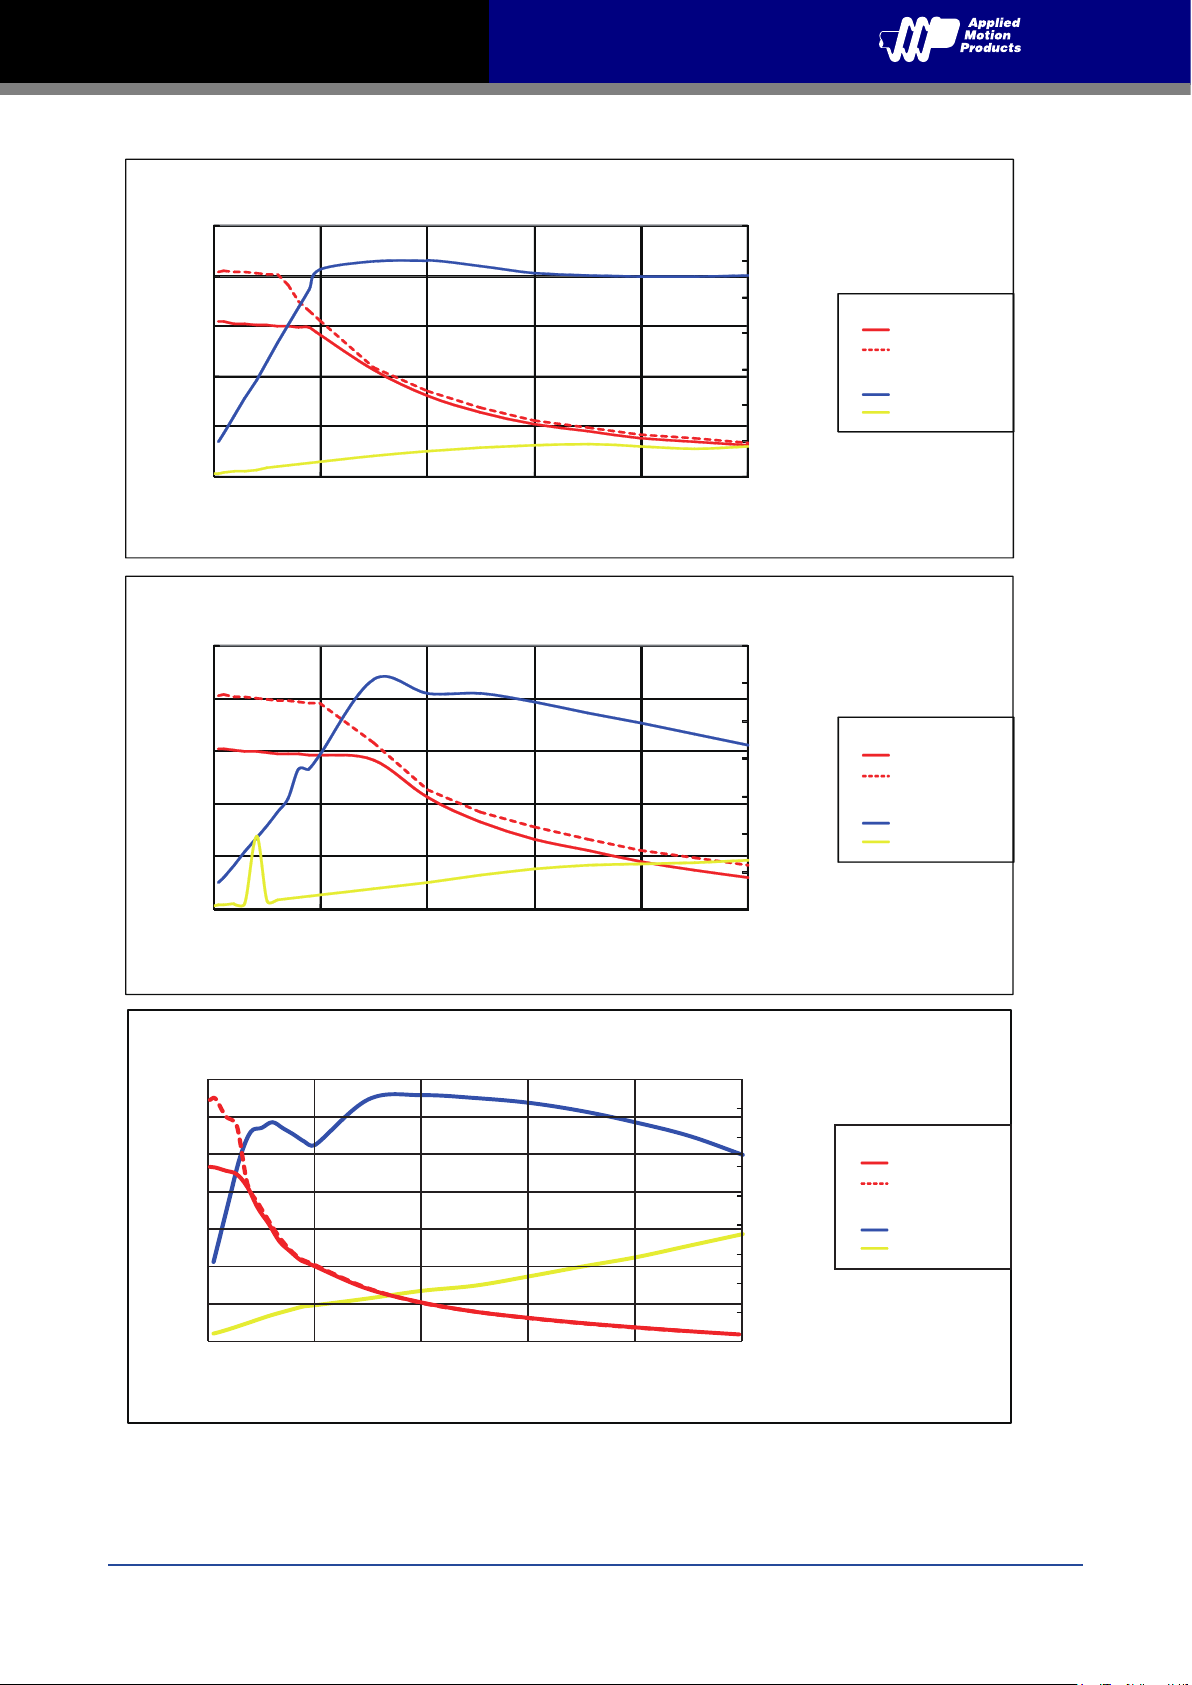
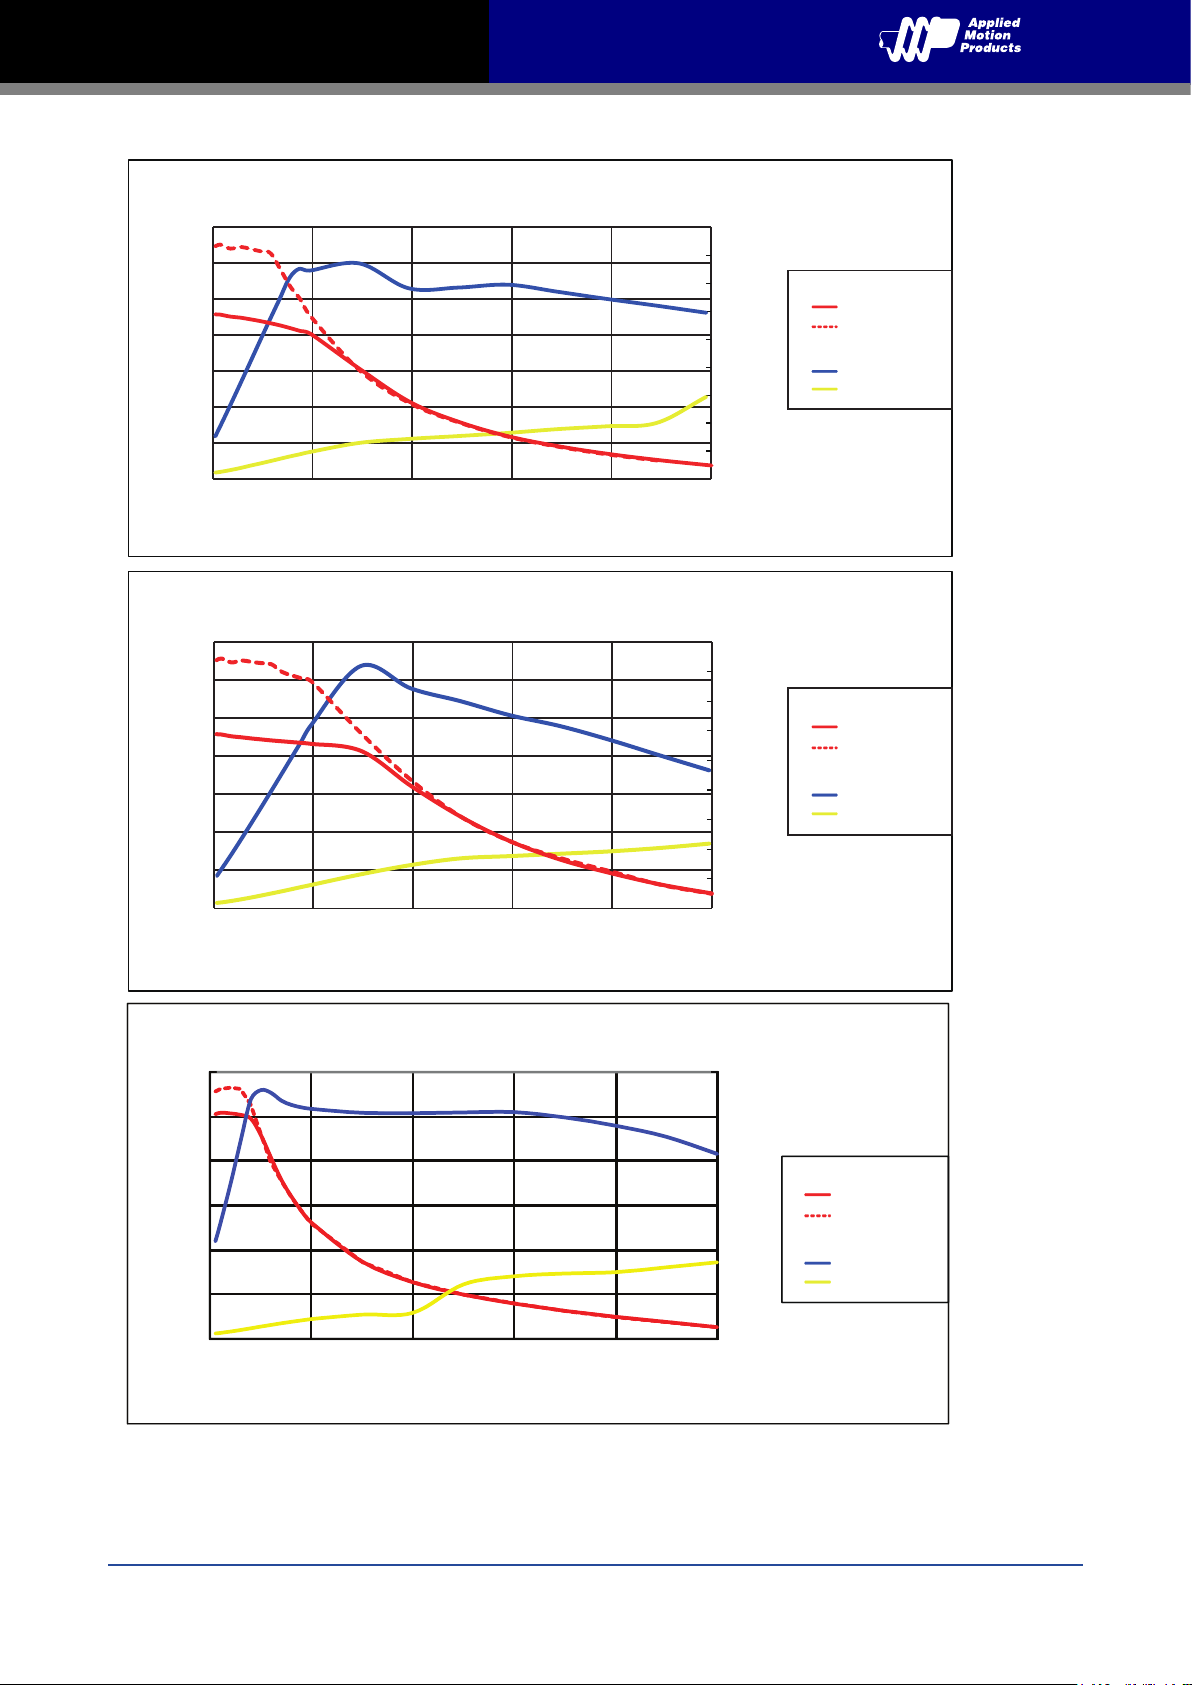
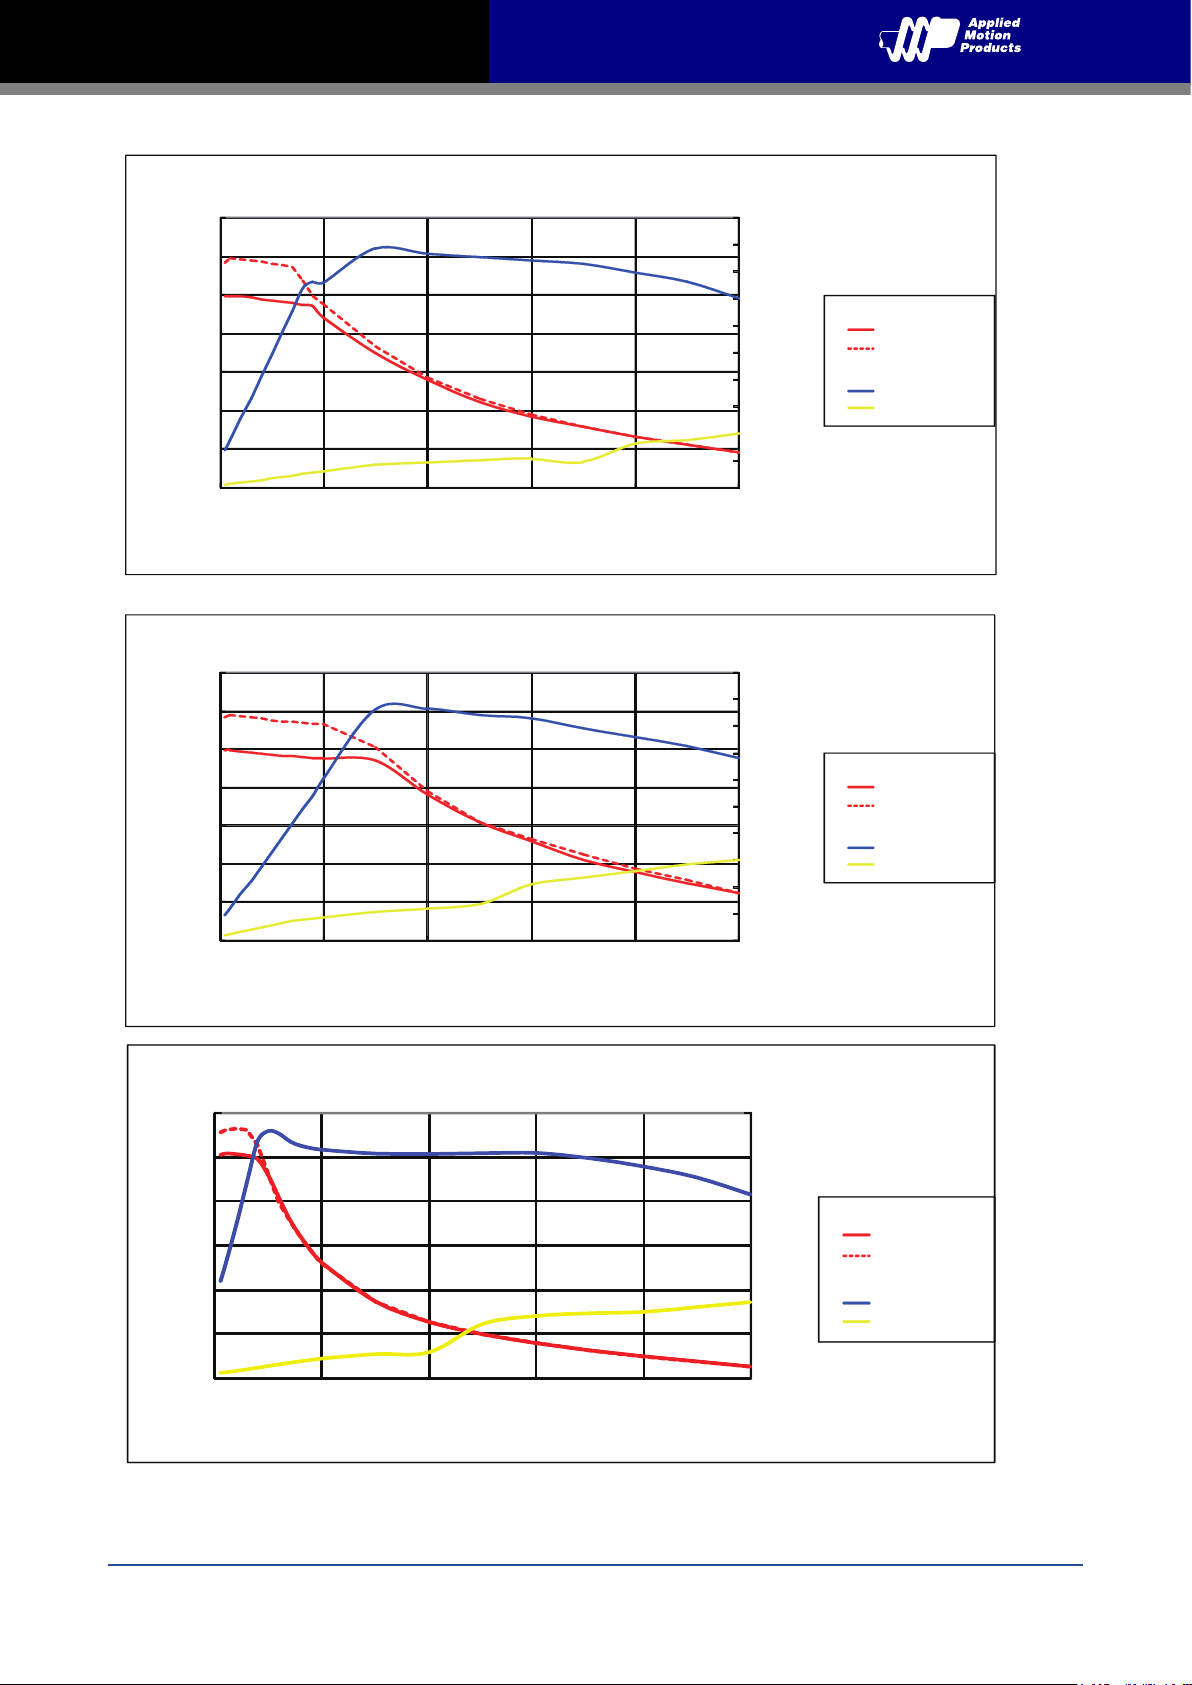
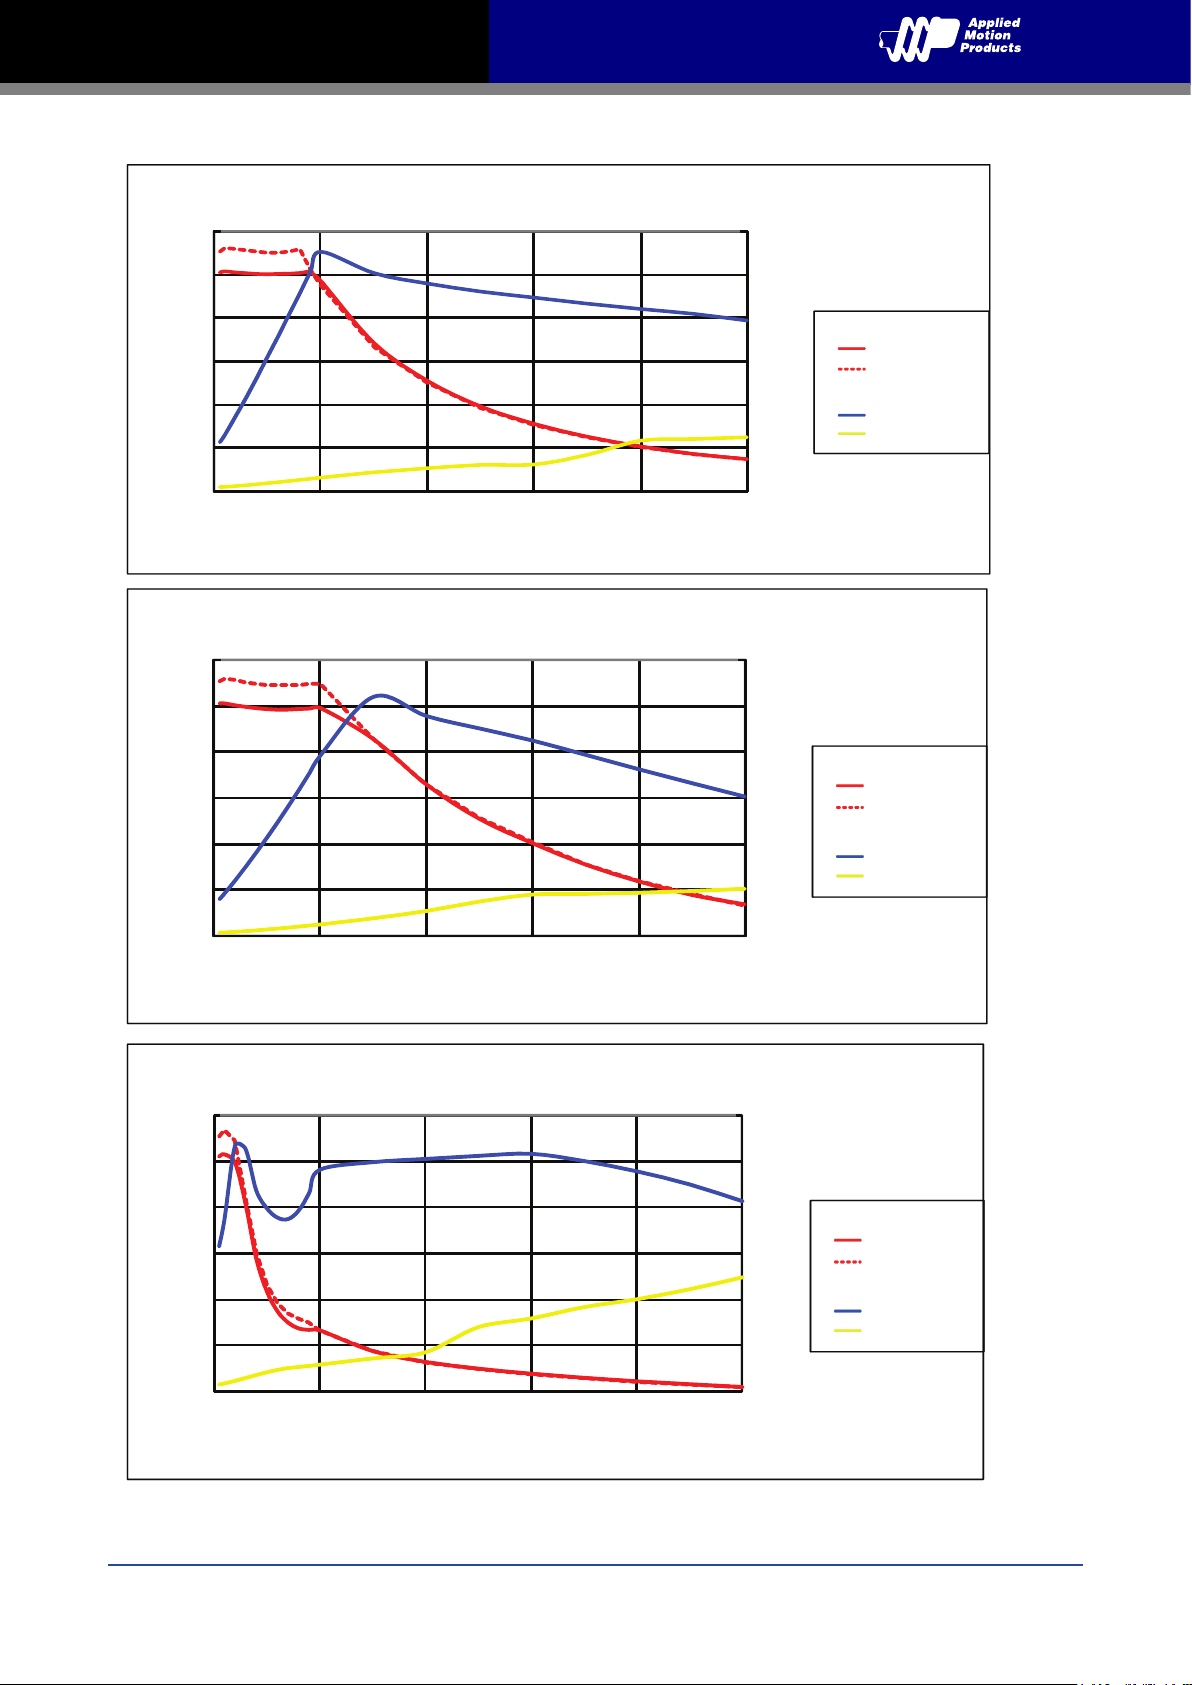
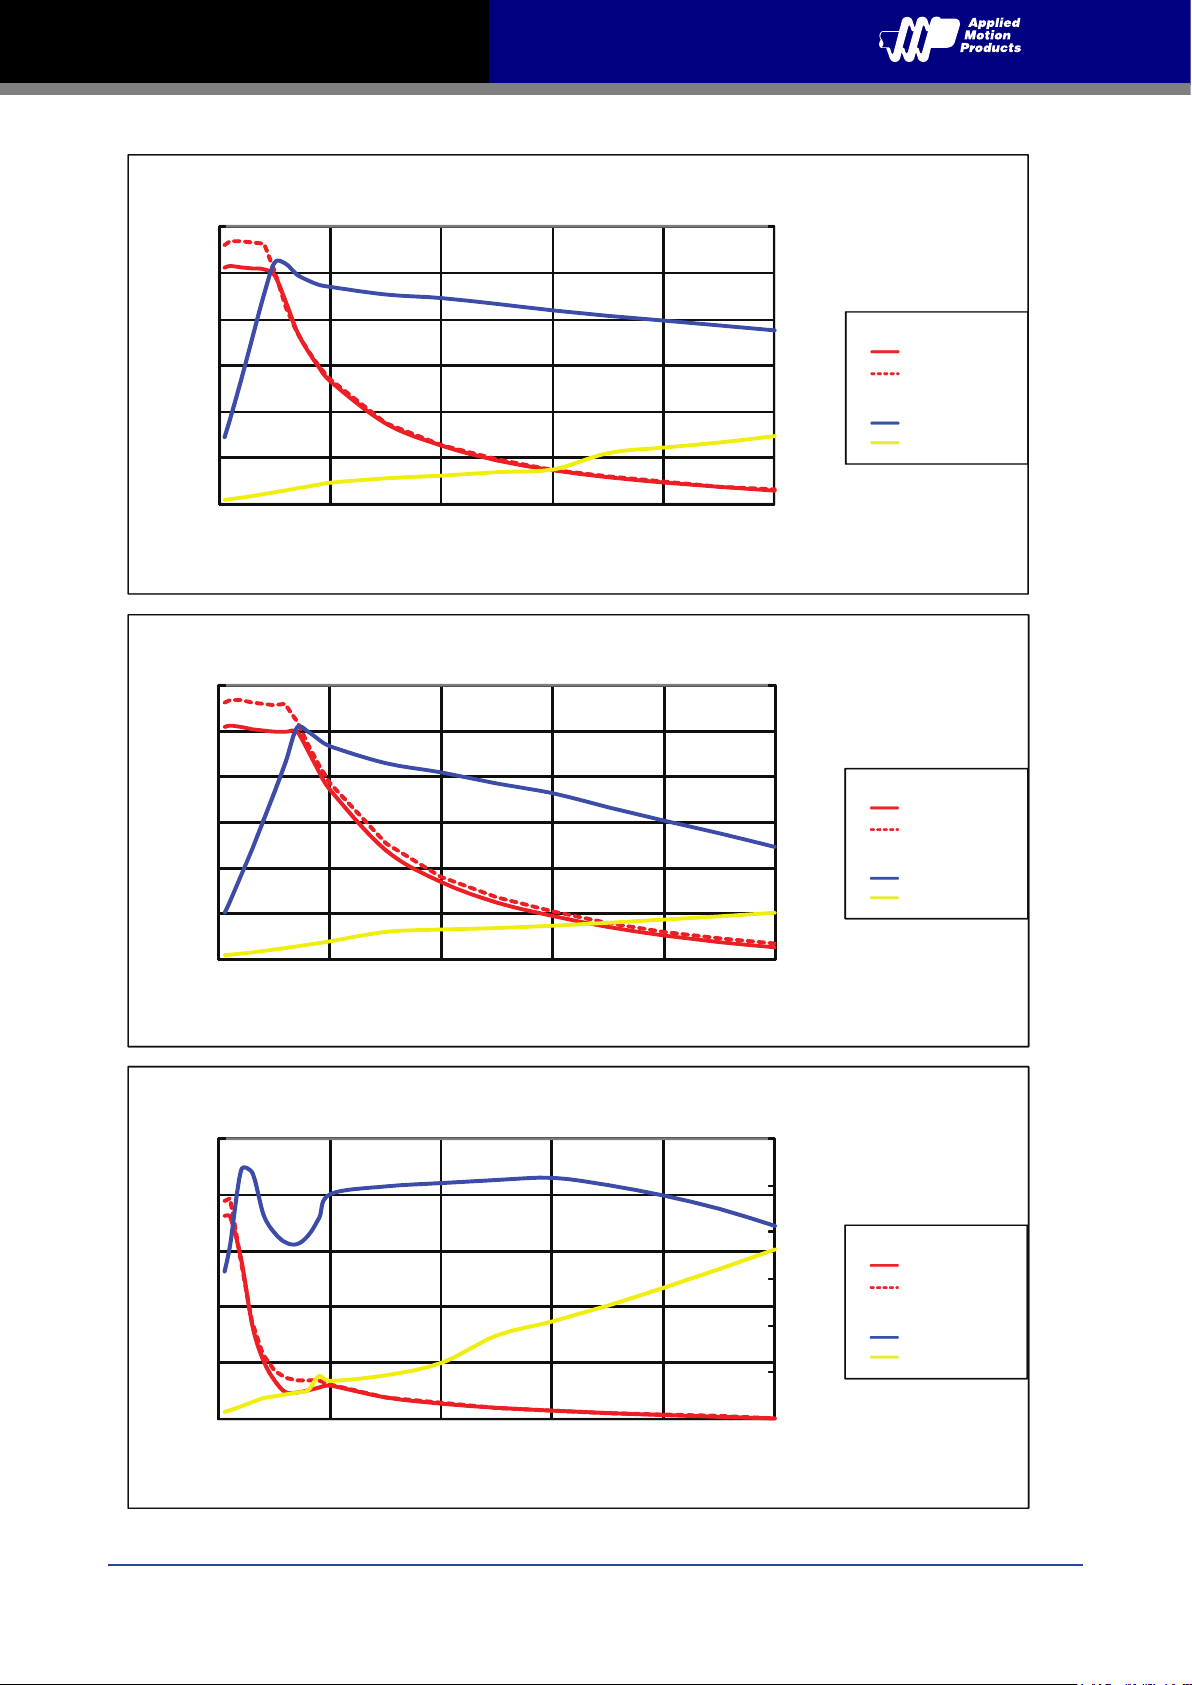
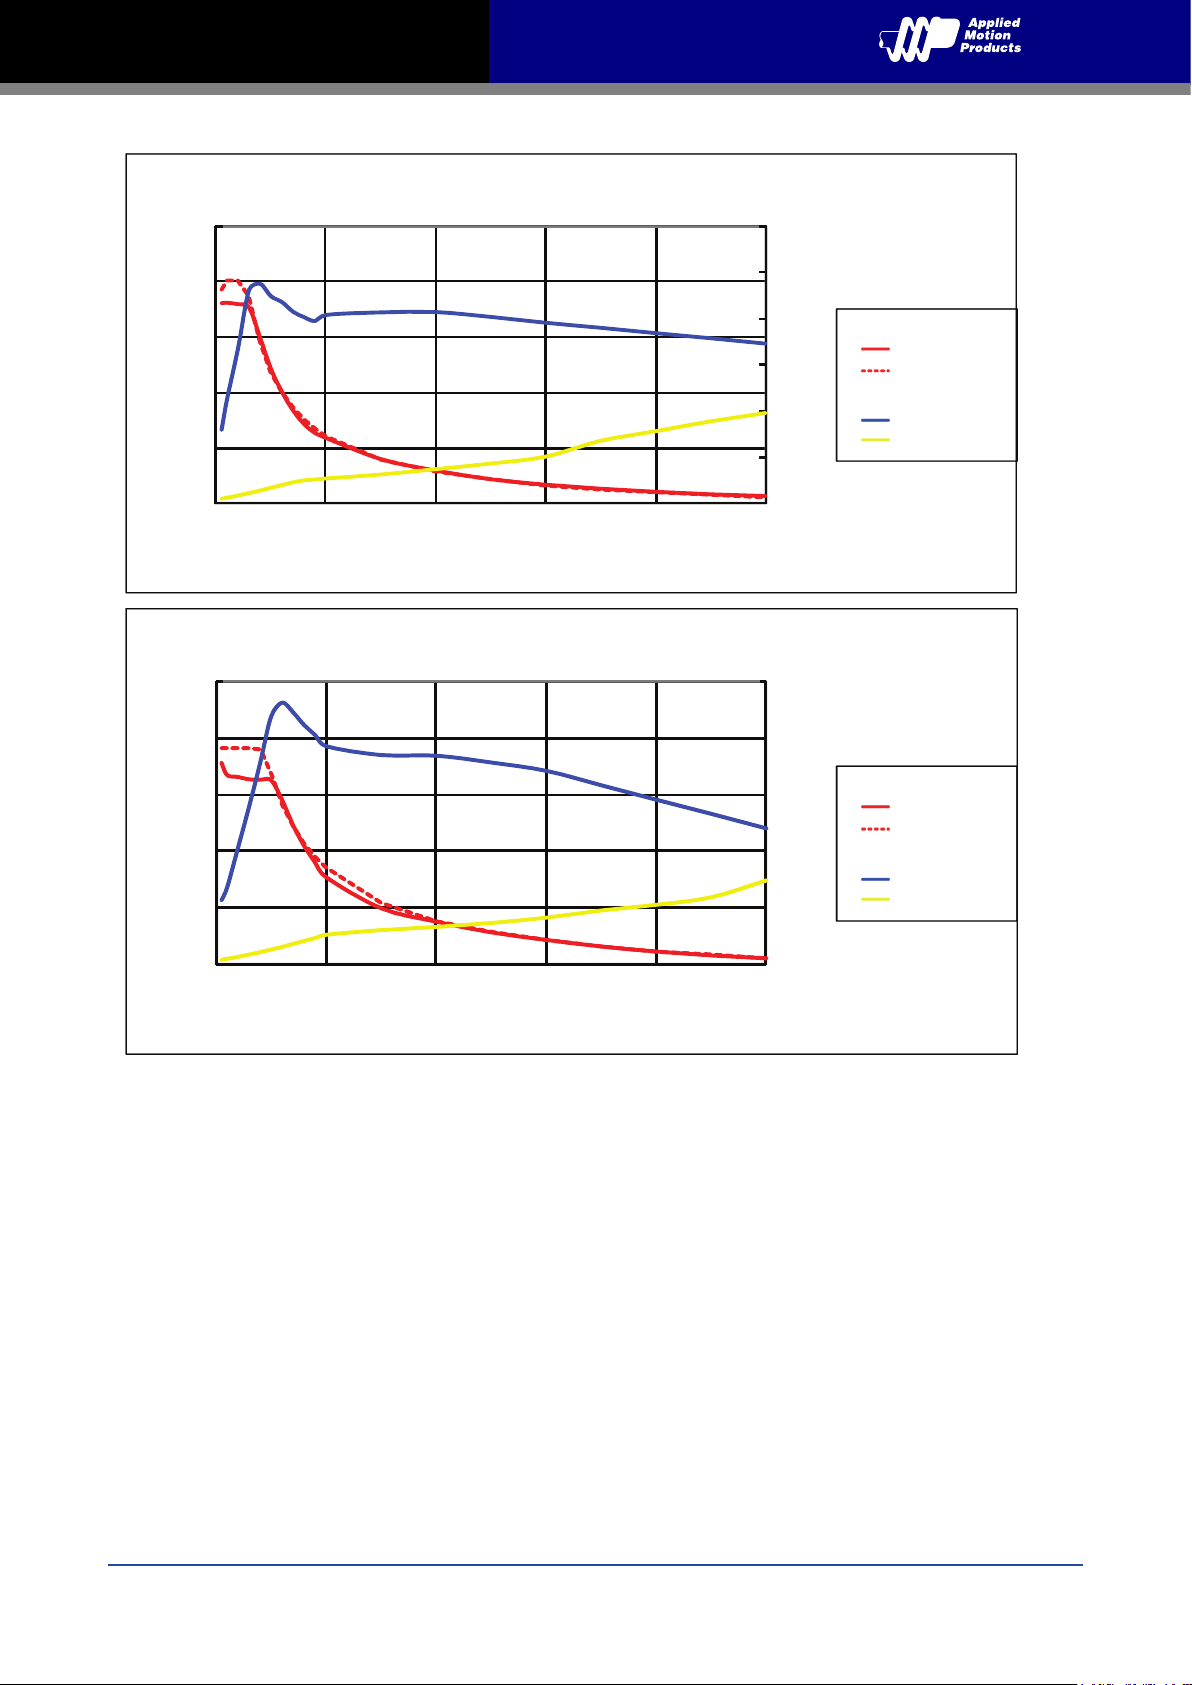
2.8.2 Supply Current
The maximum supply currents required by the SSDC are shown in the charts below at different power supply voltage inputs.
The SSDC power supply current is lower than the winding currents because it uses switching amplifiers to convert a high
voltage and low current into lower voltage and higher current. The more the power supply voltage exceeds the motor voltage,
the less current will be required from the power supply.
It is important to note that the current draw is significantly different at higher speeds depending on the torque load to the
motor. Estimating how much current is necessary may require a good analysis of the load the motor will encounter.
21
Rev. 1.0
7/31/2019
Page 22
SSDC-R/C/IP Hardware Manual
0
0.5
1
1.5
0
0.1
0.2
0.3
0.4
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT17-SS1DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply C urrent
Full Load
No Load
0
0.5
1
1.5
0
0.1
0.2
0.3
0.4
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT17-SS1DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
0
0.1
0.2
0.3
0.4
0.5
0.6
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT17-SS2DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
Rev. 1.0
7/31/2019
22
Page 23
SSDC-R/C/IP Hardware Manual
0
0.5
1
1.5
0
0.1
0.2
0.3
0.4
0.5
0.6
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT17-SS2DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply C urrent
Full Load
No Load
0
0.5
1
1.5
0
0.1
0.2
0.3
0.4
0.5
0.6
0.7
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT17-SS3DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
0
0.1
0.2
0.3
0.4
0.5
0.6
0.7
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT17-SS3DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
23
Rev. 1.0
7/31/2019
Page 24
SSDC-R/C/IP Hardware Manual
0
0.5
1
1.5
0
0.3
0.6
0.9
1.2
1.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT17-SS4DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
0
0.3
0.6
0.9
1.2
1.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT17-SS4DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
2
2.5
3
3.5
0
0.3
0.6
0.9
1.2
1.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT23-SS2DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
Rev. 1.0
7/31/2019
24
Page 25
SSDC-R/C/IP Hardware Manual
0
0.5
1
1.5
2
2.5
3
3.5
0
0.3
0.6
0.9
1.2
1.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT23-SS2DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
2
2.5
3
3.5
0
0.3
0.6
0.9
1.2
1.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT23-SS2DG_ 70V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
2
2.5
3
3.5
0
0.5
1
1.5
2
2.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT23-SS3DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
25
Rev. 1.0
7/31/2019
Page 26
SSDC-R/C/IP Hardware Manual
0
0.5
1
1.5
2
2.5
3
3.5
0
0.5
1
1.5
2
2.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT23-SS3DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
2
2.5
3
3.5
0
0.5
1
1.5
2
2.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT23-SS3DG_ 70V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
Torque(N.m)
Speed(RPS)
HT23-SS4DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
2
2.5
3
3.5
4
4.5
0
1
0.5
2
1.5
2.5
3
3.5
0 10 20 30 40 50
Rev. 1.0
7/31/2019
26
Page 27
SSDC-R/C/IP Hardware Manual
0
0.5
1
1.5
2
2.5
3
3.5
4
4.5
0
1
0.5
2
1.5
2.5
3
3.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT23-SS4DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
2
2.5
3
3.5
4
4.5
0
1
0.5
2
1.5
2.5
3
3.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT23-SS4DG_ 70V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
1
2
3
4
5
6
0
0.5
1
1.5
2
2.5
3
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT24-SS3DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
27
Rev. 1.0
7/31/2019
Page 28
SSDC-R/C/IP Hardware Manual
0
0.5
1
1.5
2
2.5
3
3.5
4
4.5
5
0
0.5
1
1.5
2
2.5
3
3.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT24-SS3DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
0.5
1
1.5
2
2.5
3
3.5
4
4.5
5
0
0.5
1
1.5
2
2.5
3
3.5
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT24-SS3DG_ 70V Power
Amps
Continuous
Torque
Boost
Supply C urrent
Full Load
No Load
0
1
2
3
4
5
6
0
0.5
1
1.5
2
2.5
3
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS1DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
Rev. 1.0
7/31/2019
28
Page 29
SSDC-R/C/IP Hardware Manual
0
1
2
3
4
5
6
0
0.5
1
1.5
2
2.5
3
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS1DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
1
2
3
4
5
6
0
0.5
1
1.5
2
2.5
3
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS1DG_ 70V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
1
2
3
4
5
6
0
1
2
3
4
5
6
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS3DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
29
Rev. 1.0
7/31/2019
Page 30
SSDC-R/C/IP Hardware Manual
0
1
2
3
4
5
6
0
1
2
3
4
5
6
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS3DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
1
2
3
4
5
6
0
1
2
3
4
5
6
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS3DG_ 70V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
1
2
3
4
5
6
0
2
4
6
8
10
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS5DG_ 24V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
Rev. 1.0
7/31/2019
30
Page 31
SSDC-R/C/IP Hardware Manual
0
1
2
3
4
5
6
0
2
4
6
8
10
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS5DG_ 48V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
0
1
2
3
4
5
0
2
4
6
8
10
0 10 20 30 40 50
Torque(N.m)
Speed(RPS)
HT34-SS5DG_ 70V Power
Amps
Continuous
Torque
Boost
Supply Current
Full Load
No Load
31
Rev. 1.0
7/31/2019
Page 32
SSDC-R/C/IP Hardware Manual
J2
2.9 Connecting the Motor
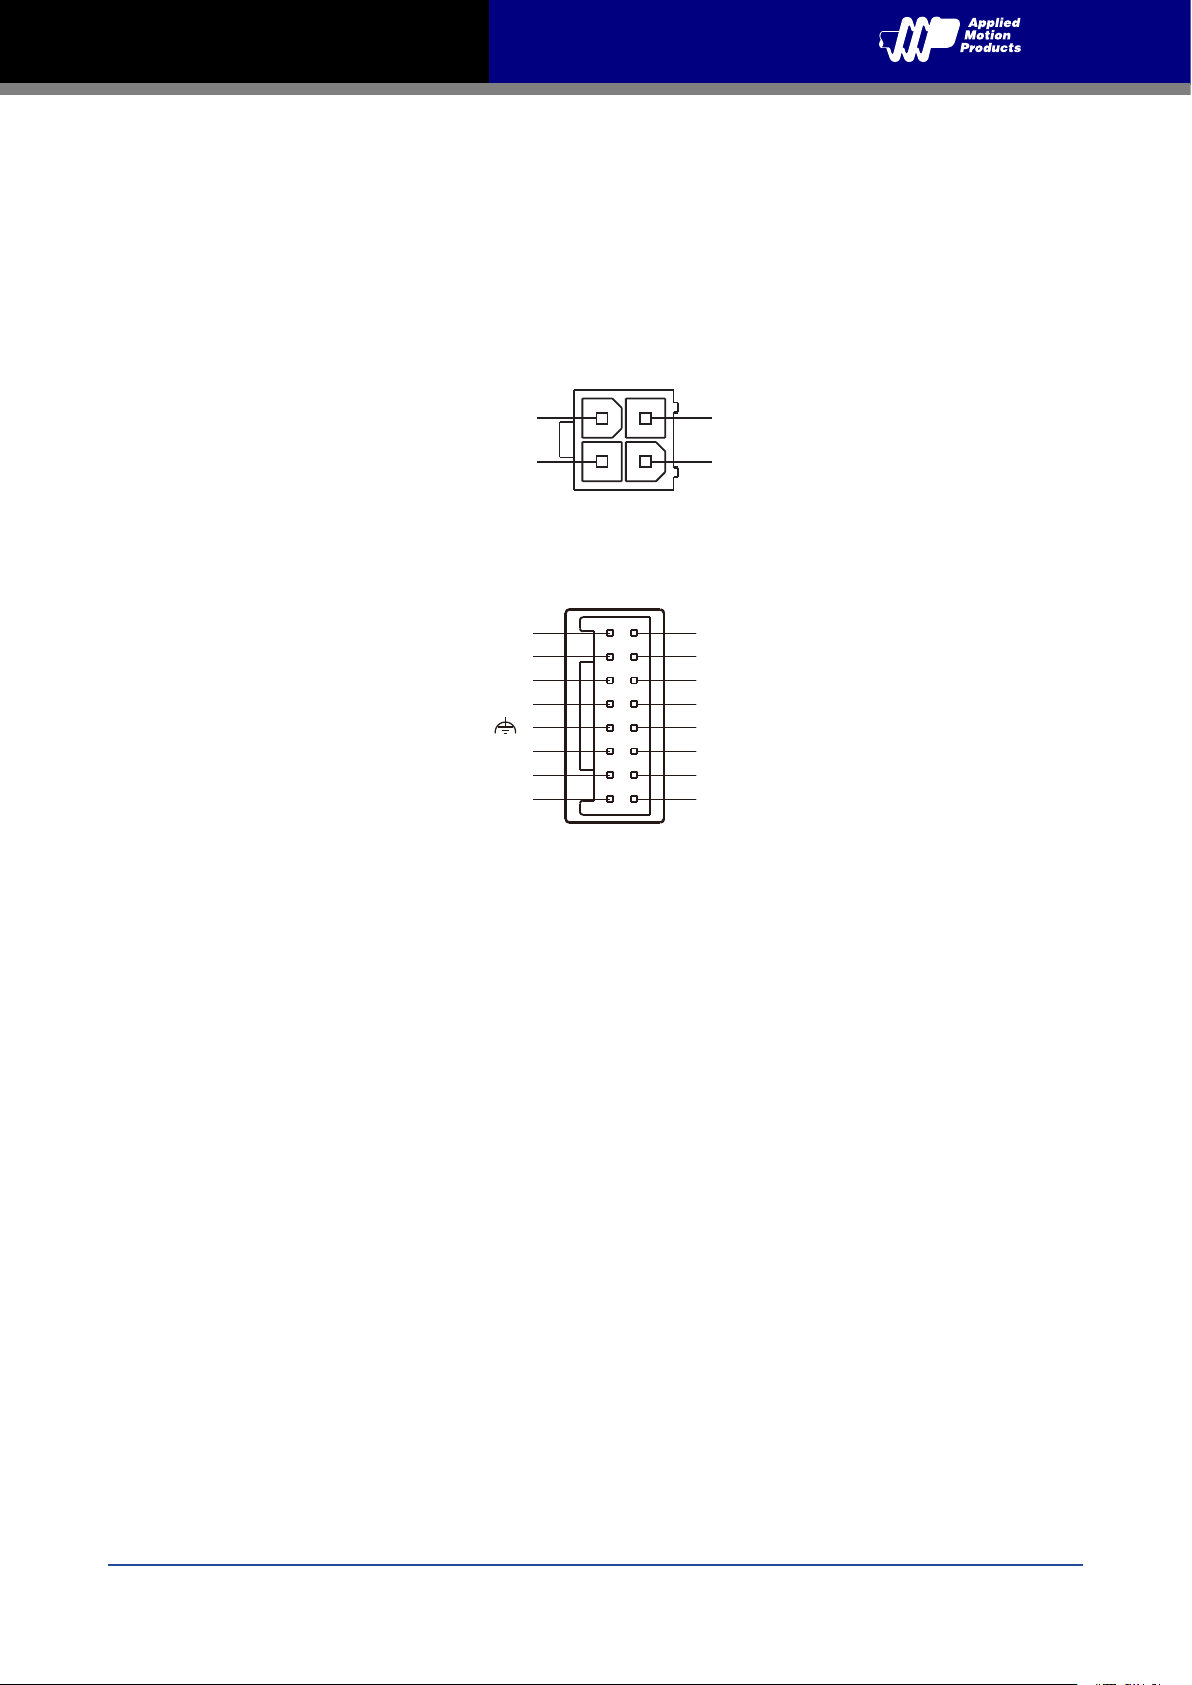
The StepSERVO motors have two cables. One is the motor power cable, the other one is the encoder feedback cable. Plug
the motor power cable into the motor connector on the drive and plug the encoder feedback cable into the encoder feedback
connector on the drive.
(NOTE:Do not damage or drag the cables on the motor.)
MMAA
MMAA++
33
-
4
11
MMBB
--
2
MMBB++
Motor connector on the driver
J3
13
15
11
1
A+
3
B+
5
Z+
7
+5 V
9
NC
U+
V+
W+
2
A-
4
B-
6
Z-
8
GN D
10
12
U-
14
V-
16
W-
Encoder connector on the driver
Please check the information of mating connectors, extended motor cable and extended encoder cable in below section
”Optional Accessories (Sold separately)”
Rev. 1.0
7/31/2019
32
Page 33
SSDC-R/C/IP Hardware Manual
3 Inputs and Outputs
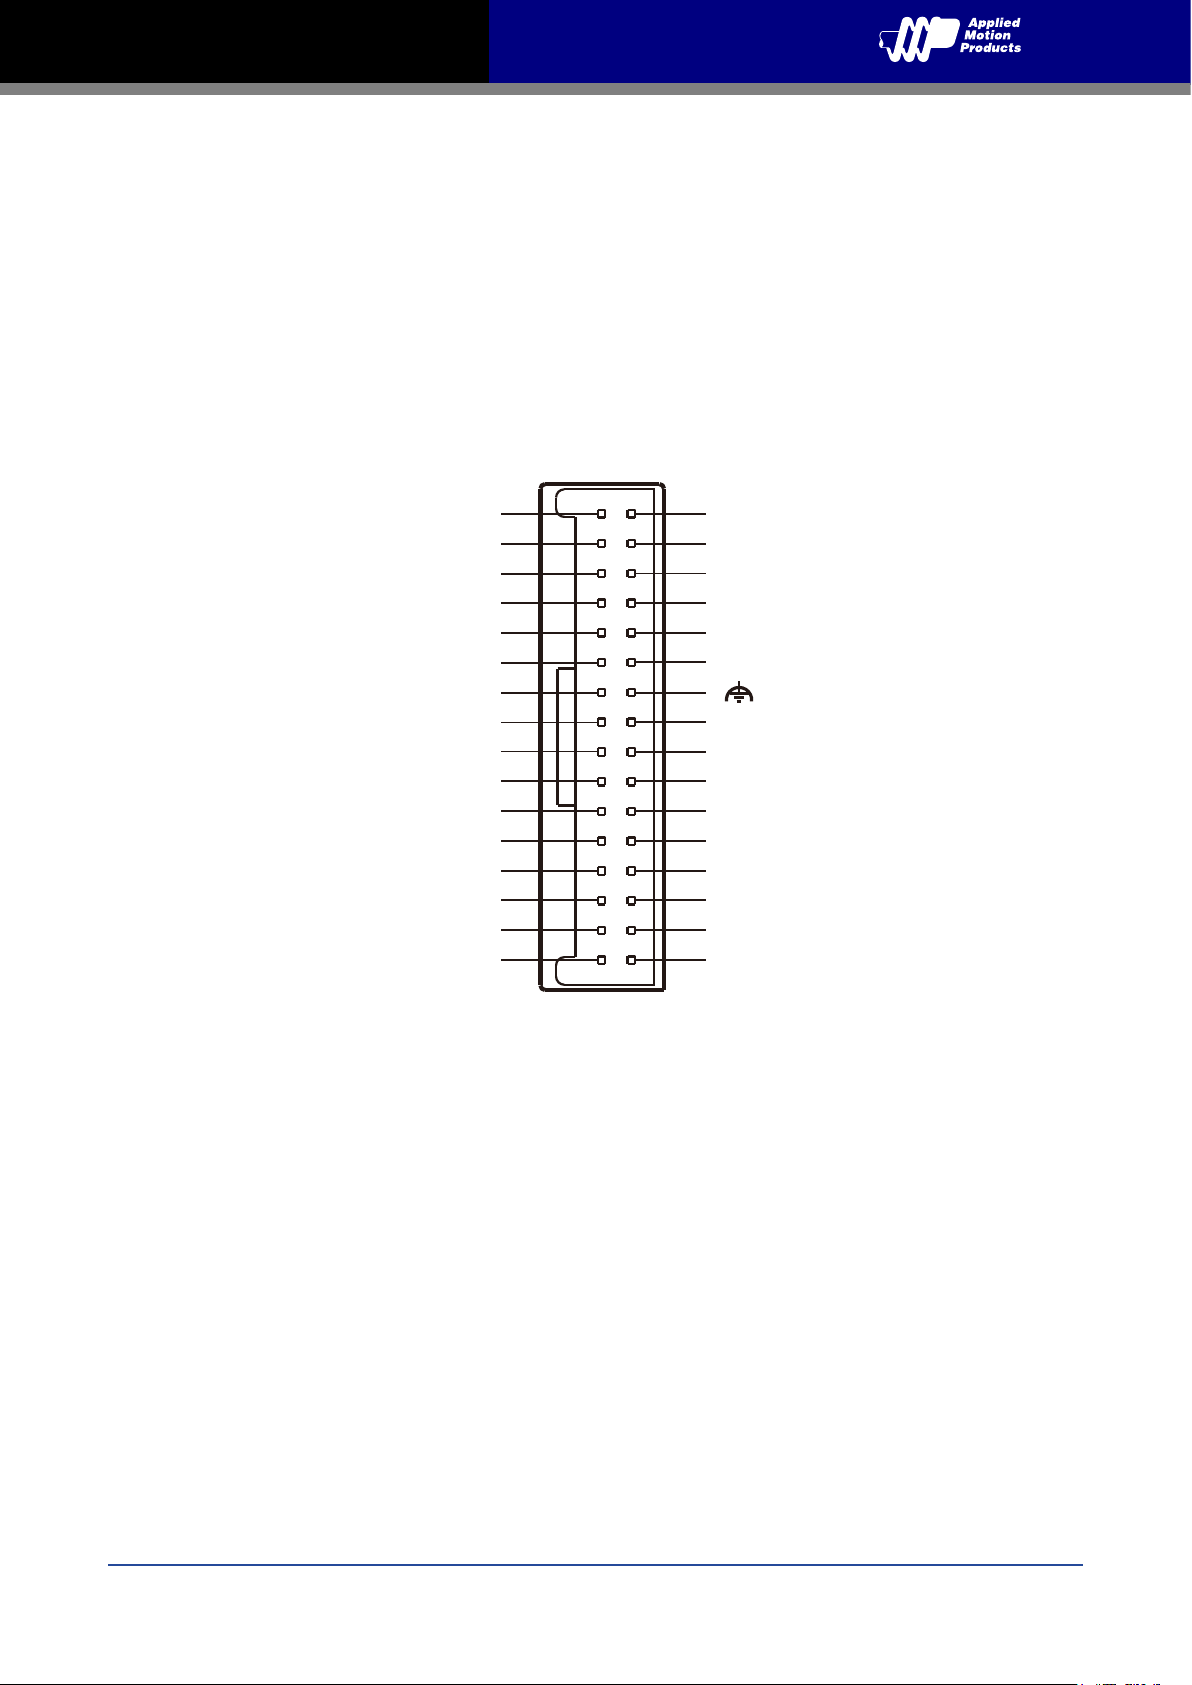
SSDC inputs and outputs include
• 8 optically isolated digital inputs,5 - 24VDC logic
• 4 Optically isolated, Open Collector, 30V/100 mA max,
• 2 analog inputs can be configured to 0-5V, 0-10V, ±5V or ±10V signal ranges
• Differential encoder outputs (A±, B±, Z±), 26C31 line driver, 20 mA sink or source max
• Secondary encoder signal input(single-ended or differential) for full closed-loop control function
J4
X1 X2 X3 X4 -
X6
X8
XC O M
+5 V
AI N 2
Y1 Y2 Y3 -
Y4 EN C AEN C BEN C Z -
2
4
6
8
10
12
14
16
18
20
22
24
26
28
30
32
I/O Connector Diagram
1
3
5
7
9
11
13
15
17
19
21
23
25
27
29
31
X1 +
X2 +
X3 +
X4 +
X5
X7
GN D
AI N 1
Y1 +
Y2 +
Y3 +
Y4 +
EN C A+
EN C B +
EN C Z +
33
Rev. 1.0
7/31/2019
Page 34
SSDC-R/C/IP Hardware Manual
3.1 Digital Inputs
3.1.1 X1, X2, X3 and X4 Digital Inputs
X1, X2: Optically isolated, differential, 5-24VDC; Minimum pulse width = 250ns, Maximum pulse frequency = 2MHz;
X3, X4: Optically isolated, differential, 5-24VDC; Minimum pulse width = 100μs, Maximum pulse frequency = 5KHz
X1 can be configured as general purpose input
X2 can be configured as general purpose input
X3 can be configured as CW limit sensor input or general purpose input
X4 can be configured as CCW limit sensor input or general purpose input
Please use StepSERVO Quick Tuner software to configure the function of X1, X2, X3 and X4.
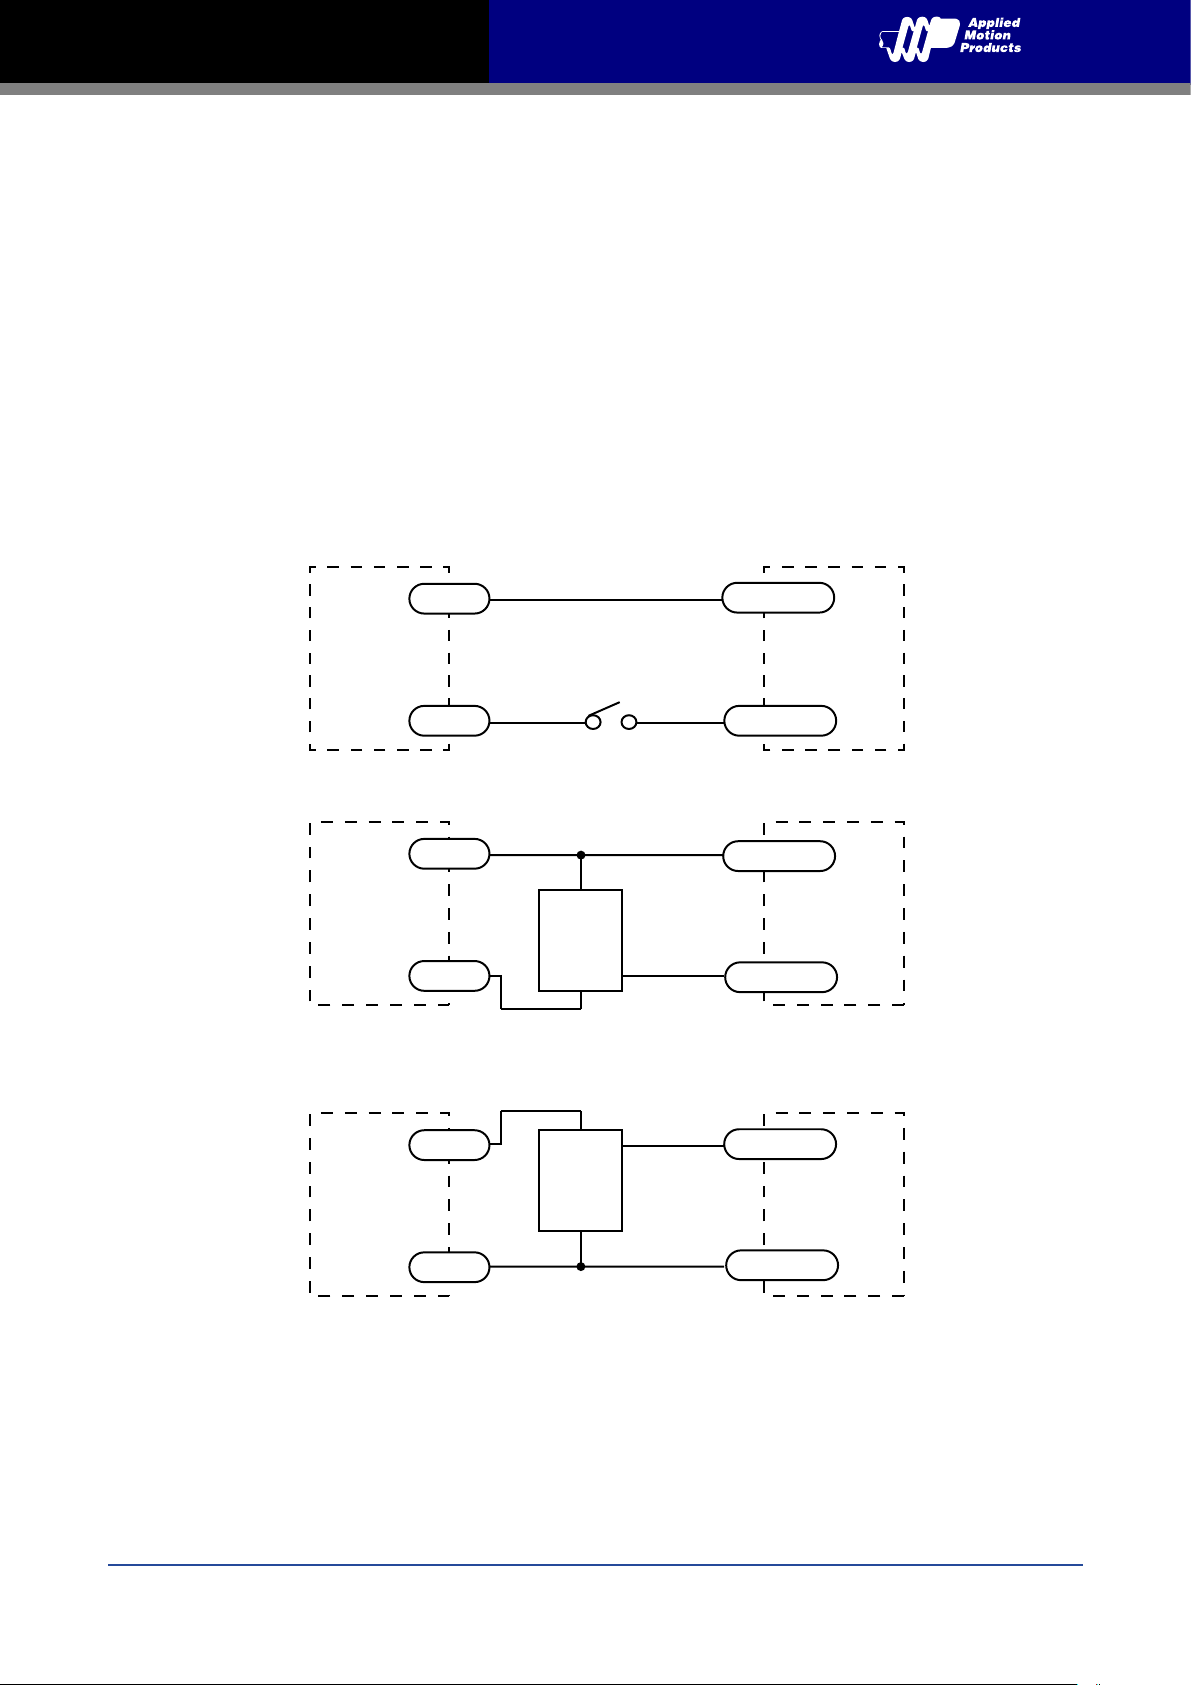
The diagram below show how to connect the X1, X2, X3 and X4 to various commonly used devices.
5 - 24V
Power Supply
Connecting a switch or relay to an input
5 - 24V
Power Supply
Connecting a NPN type output to an input
5 - 24V
Power Supply
+
-
+
-
+
Switch or Relay
(Closed: logic low)
+
NPN type
Output
output
-
+
PNP type
Output
output
-
X1/2/3/4+
SSDC
X1/2/3/4-
X1/2/3/4+
SSDC
X1/2/3/4-
X1/2/3/4+
SSDC
Rev. 1.0
7/31/2019
-
X1/2/3/4-
Connecting a PNP type output to an input
34
Page 35
SSDC-R/C/IP Hardware Manual
3.1.2 X5, X6, X7 and X8 Digital Inputs
X5 ~ X8: Optically isolated, differential, 5-24VDC; Minimum pulse width = 100μs, Maximum pulse frequency = 5KHz;
X5 can be configured as servo on input or general purpose input
X6 can be configured as alarm reset signal input or general purpose input
X7 can be configured as Touch Probe 1 trigger input or general purpose input
X8 can be configured as Touch Probe 2 trigger input or general purpose input
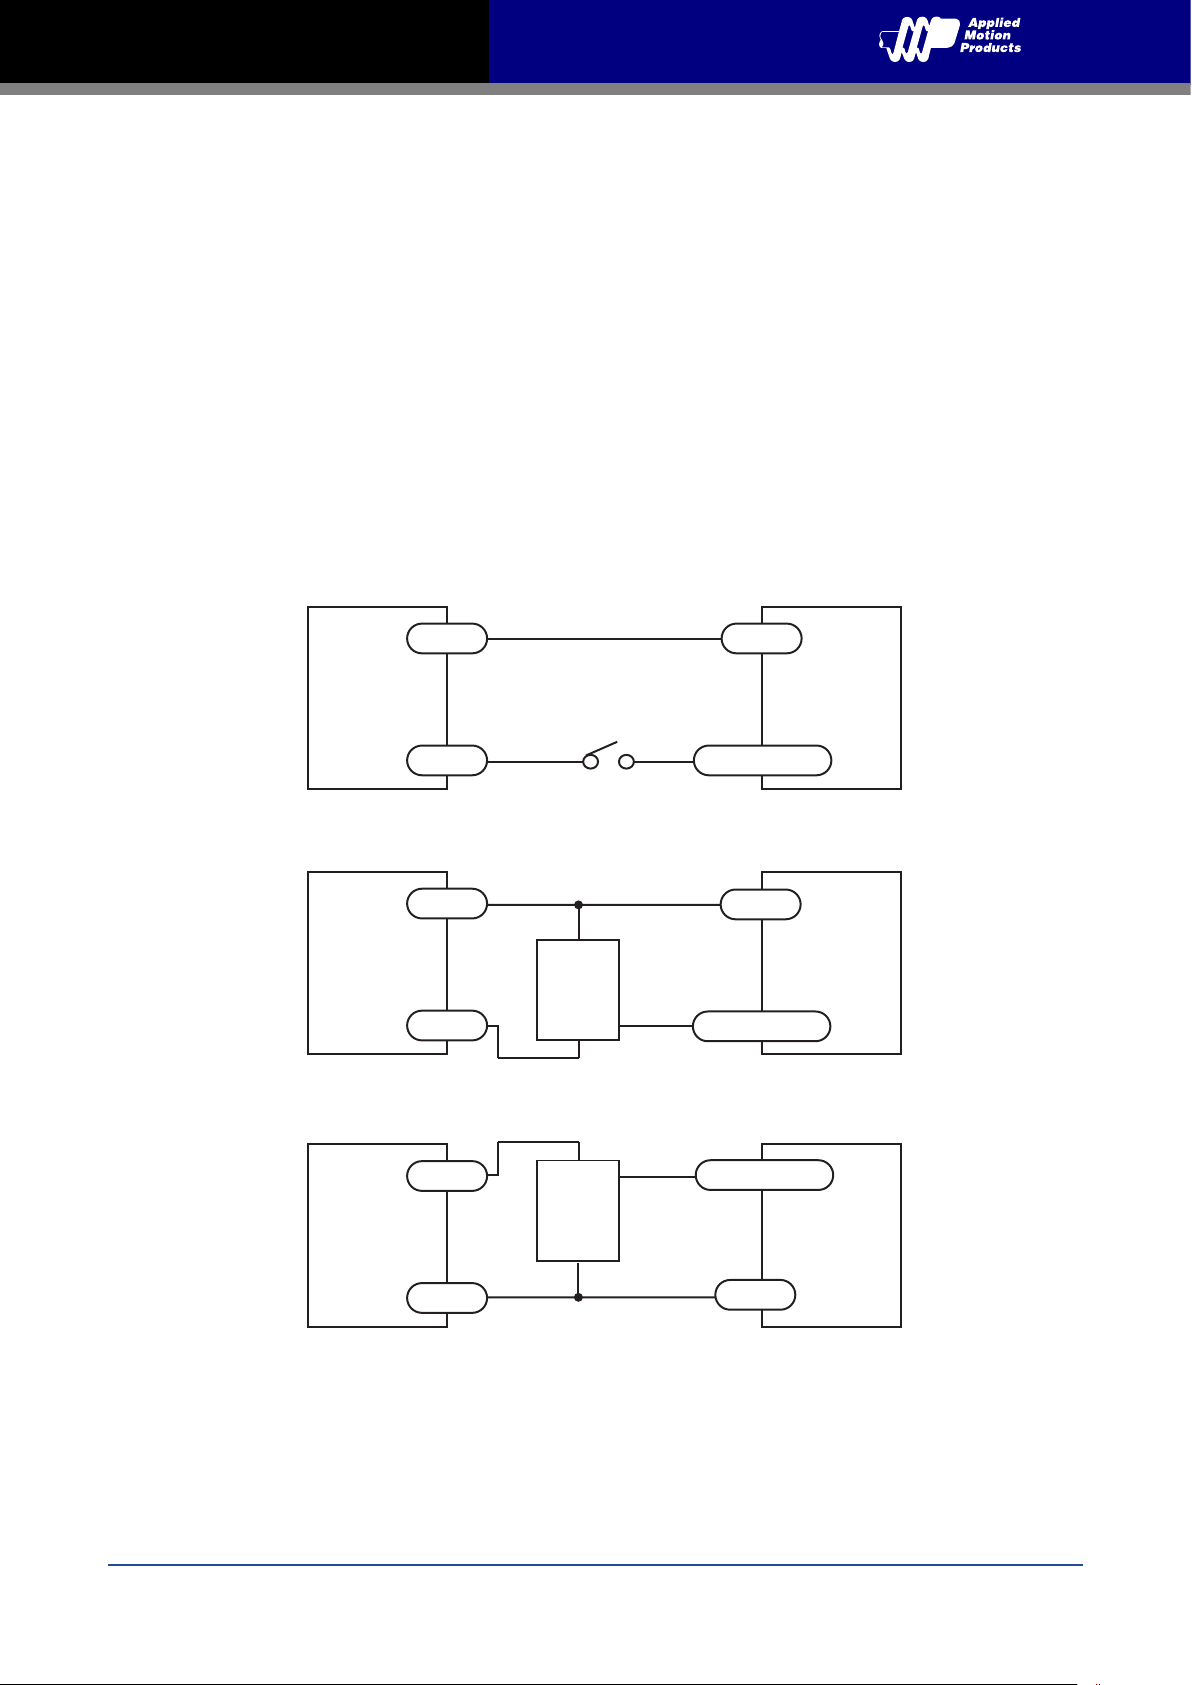
Since the input is an optically isolated circuit, a 5-24V power supply is needed.
XCOM is an electronics term for a single-ended signal connection to a common voltage. In the case of SS series, if you
are using a sourcing(PNP) input signals, you need to connect XCOM to the ground(power supply -),if you are using a
sinking(NPN) input signals ,the XCOM need to connect to the power supply +.
Please use StepSERVO Quick Tuner software to configure the function of X5, X6, X7 and X8.
The diagram below show how to connect the X5, X6, X7 and X8 to various commonly used devices.
5 - 24V
Power Supply
Connecting a switch or relay to an input
5 - 24V
Power Supply
Connecting a NPN type output to an input
Power Supply
-
+
-
+
Switch or Relay
(Closed: logic low)
+
NPN type
Ooutput
output
-
+
PNP type
Ooutput
output
-
XCOM+
SSDC
X5/X6/X7/X8
XCOM
SSDC
X5/X6/X7/X8
X5/X6/X7/X8
SSDC5 - 24V
-
XCOM
Connecting a PNP type output to an input
35
Rev. 1.0
7/31/2019
Page 36
SSDC-R/C/IP Hardware Manual
3.2 Digital Outputs
Y1, Y2, Y3 and Y4 Digital Outputs
Y1 can be configured as alarm signal output. It can also be configured as static in position signal output(static, checking in
position when motor is stopped) ,or as dynamic in position signal output (dynamic, checking in position all the time.)
Y2 can be configured as Tach signal output, tach output produce pulsed relative to the motor position with configurable
resolution. It can also be configured as static in position signal output(static, checking in position when motor is stopped) ,or
as dynamic in position signal output (dynamic, checking in position all the time.),or as Timing signal output(50 pulses per
rotation)
Y3 can be configured as signal output to release brake. It can also be configured as static in position signal output(static,
checking in position when motor is stopped) ,or as dynamic in position signal output (dynamic, checking in position all the
time.)
Y4 can be configured as static in position signal output( static, checking in position when motor is stopped) ,or as dynamic
in position signal output (dynamic, checking in position all the time.)
Y1, Y2, Y3 and Y4 can be configured by StepSERVO Quick Tuner.
Below show how to connect to the output:
(NOTE: DO NOT connect outputs to more than 30VDC power supply and the current of each output terminal must not exceed
100mA)
Rev. 1.0
7/31/2019
36
Page 37
SSDC-R/C/IP Hardware Manual
Connecting a sourcing output to load
Connecting a sourcing output to PLC's input
Driving a relay
Connecting a sinking output to PLC's input
Y1/2/3/4-
Y1/2/3/4+
PLC
+
–
COM
IN
SSDC
5 - 24V
Power Supply
Y1/2/3/4-
Y1/2/3/4+
CLP
+ –
IN
COM
SSDC
5 - 24V
Power Supply
+ –
Y1/2/3/4-
Y1/2/3/4+
SSDC
5 - 24V
Power Supply
Load
Y1/2/3/4-
Y1/2/3/4+
+ –
relay
SSDC
5 - 24V
Power Supply
1N4935 suppression diode
37
Rev. 1.0
7/31/2019
Page 38
SSDC-R/C/IP Hardware Manual
3.3 Analog Inputs
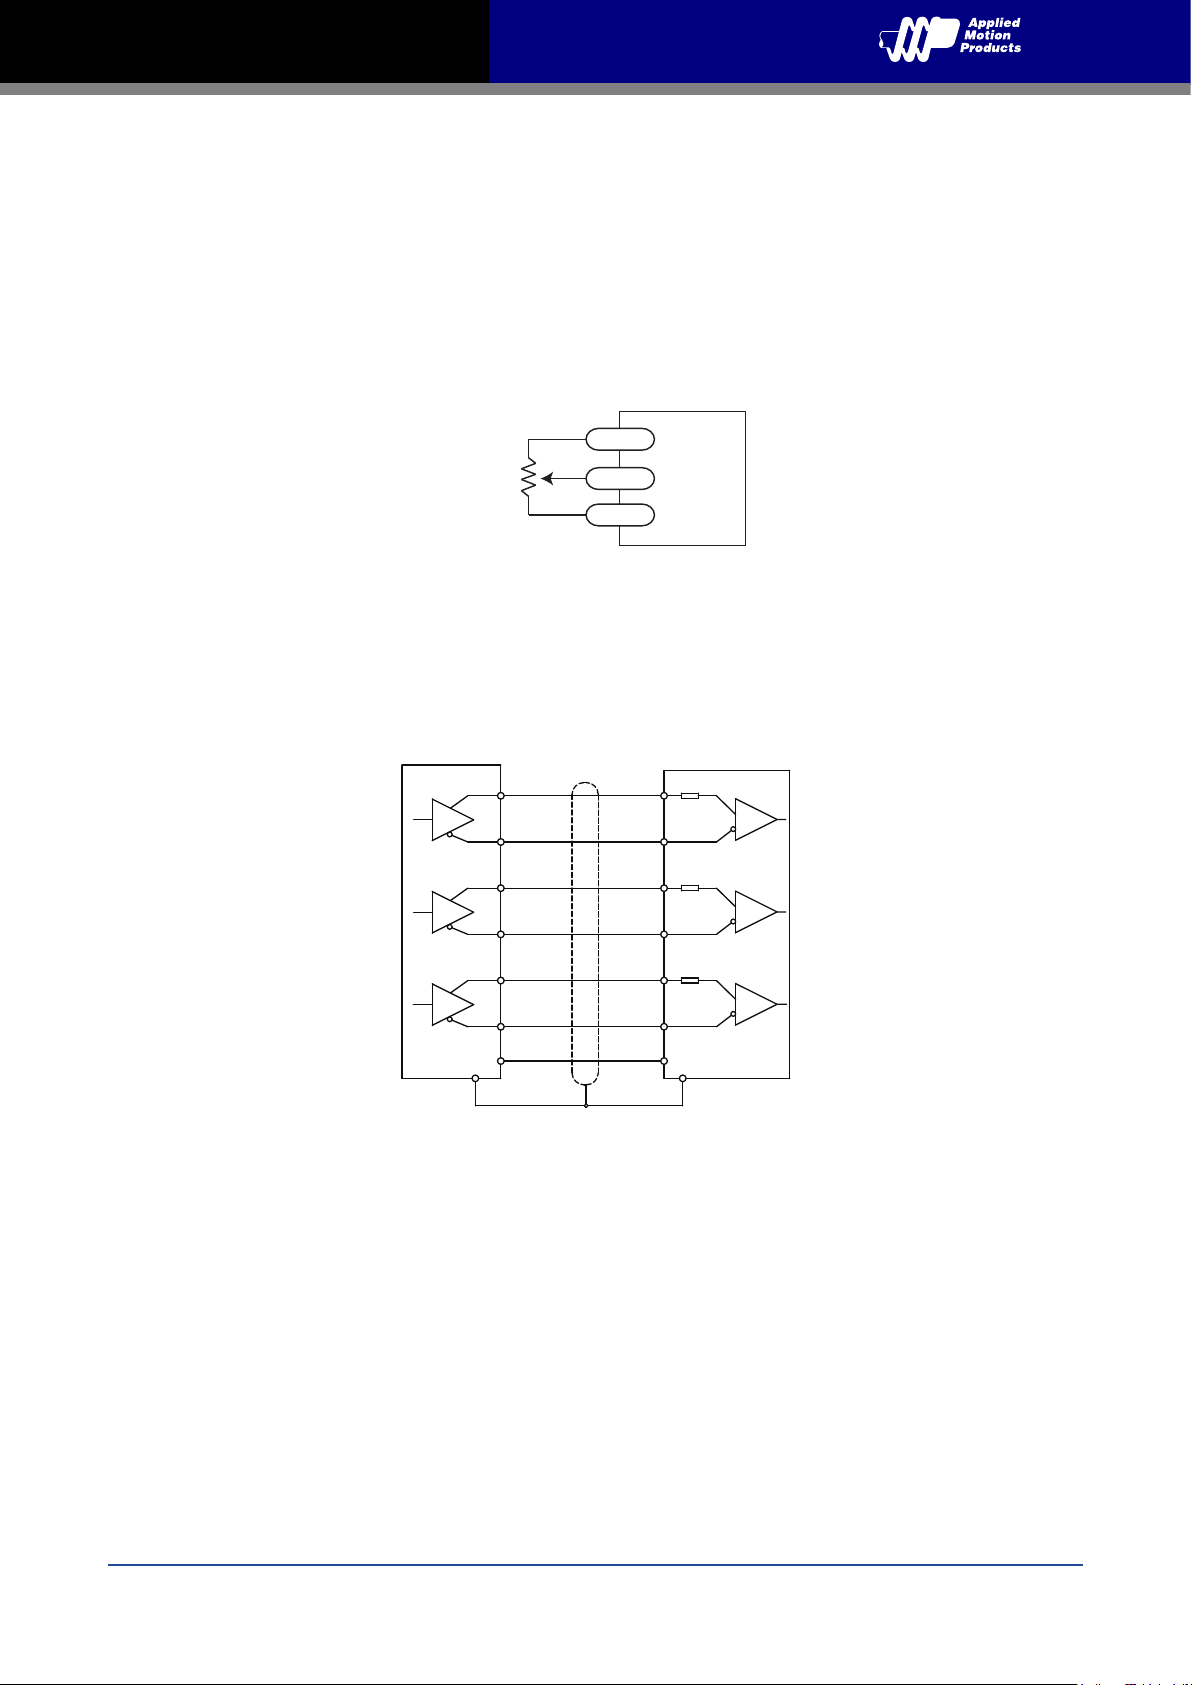
SSDC series drive has two analog signal inputs which can accept signal range of 0-5V, 0-10V, ±5V and ±10V. The drive can
be configured to operate at velocity mode or position mode that is proportional to the analog input.
Use the StepSERVO Quick Tuner to configure the input range, offset, deadband and noisy filter frequency.
SSDC series provides a +5V/100mA limit power supply that can be used to power external devices such as potentiometer.
It is not the most accurate supply for reference, for more precise readings use an external supply that can provide desired
accuracy.
+5V OUT
1 - 10k
Ω
pot
AIN
GND
Connecting a potentiometer to an analog input
SSDC
3.4 Encoder Output
SSDC has differential encoder outputs (ENC A+/-, ENC B+/-, ENC Z+/-), with 26C31 line driver, 20mA sink or source current
in max. These signals can be connected to the motion controller to be a feedback of motor position.
SSDC
ENC A+
ENC A-
ENC B+
ENC B-
ENC Z+
ENC Z-
DGND DGND
FG FG
Host Controller
A+
A-
B+
B-
Z+
Z-
Rev. 1.0
7/31/2019
38
Page 39
SSDC-R/C/IP Hardware Manual
3.5 Secondary Encoder Input
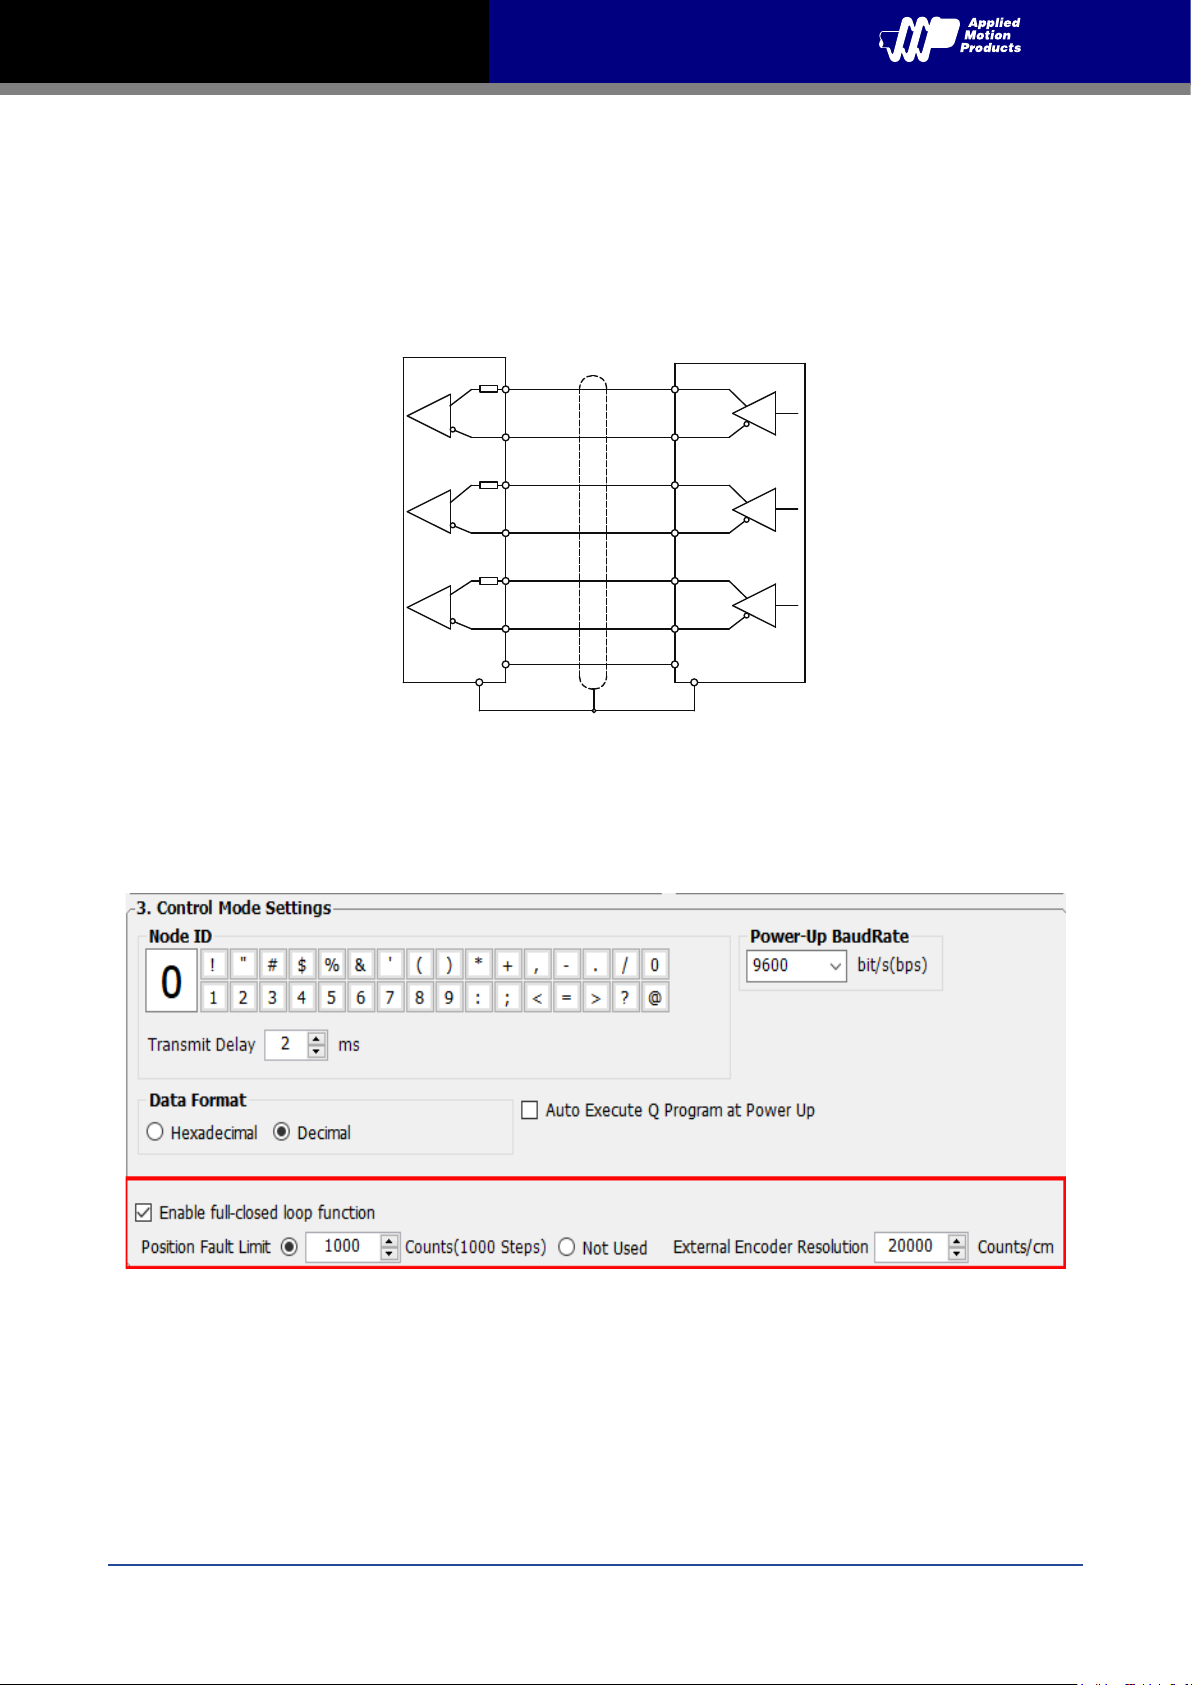
SSDC series supports secondary encoder feedback, you can connect to the load side position feedback such as linear
encoder on your drive encoder inputs. Connect the ENC A+/-目ENC B+/-目ENC Z+/-, the secondary encoder input can be
accepted both of single-ended and differential signal. If it is a single-ended signal, connect the A, B, Z to ENC A+, ENC B+,
ENC Z+, leave the ENC A-, ENC B-, ENC Z- unconnected
SSDC
ENC A+
ENC A-
ENC B+
ENC B-
ENC Z+
ENC Z-
DGND DGND
FG FG
2nd Encoder
A+
A-
B+
B-
Z+
Z-
Full colose loop, Secondary encoder function can be configured via StepSERVO Quick Tuner.
please refer to Host Command Reference Guide for more details
39
Rev. 1.0
7/31/2019
Page 40
SSDC-R/C/IP Hardware Manual
4 Mounting the Drive
Use the M3 or M4 screw to mount the SSDC series drive. The Drive should be securely fastened to a smooth, flat metal
surface will help conduct heat away from the chassis. If this is not possible, forced airflow from a fan maybe required to
prevent the drive from overheating.
• Never use the drive in a place where there is no air flow or the surrounding air is more than 40°C
• Never put the drive where it can get wet or where metal or other electrically conductive particles can get on
circuitry
• Always provide air flow around the drive. When mounting multiple SSDC drives near each other, maintain at
least 2cm of space belween drive.
5 LED Error Codes
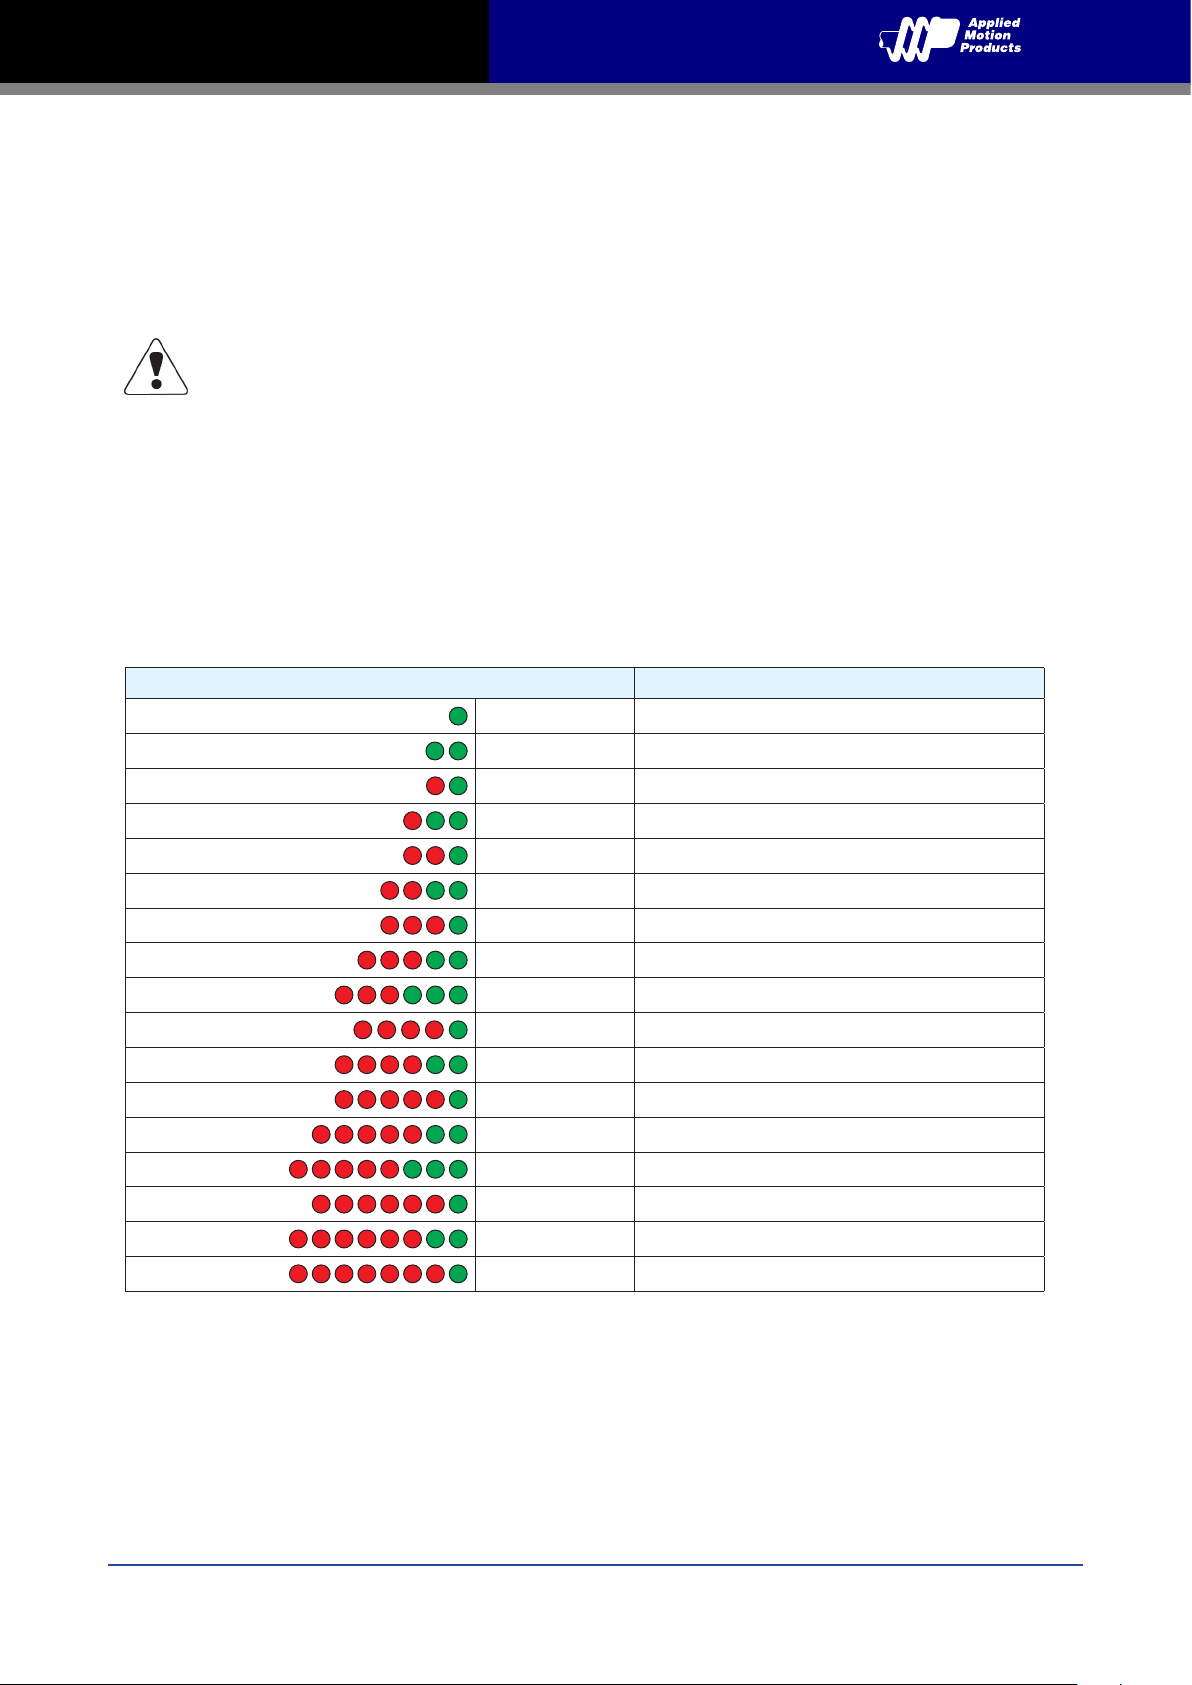
The SSDC series StepSERVO package uses red and green LEDs to indicate status. When the motor is enabled, the green LED
flashes slowly. When the green LED is solid, the motor is disabled. Errors are indicated by combinations of red and green
flashes as shown below.
Code Error
Solid green No alarm, motor disabled
Flashing green No alarm, motor enabled
1 red, 1 green
1 red, 2 green Move while disabled
2 red, 1 green CCW limit
2 red, 2 green CW limit
3 red, 1 green
3 red, 2 green
3 red, 3 green Blank Q segment
4 red, 1 green
4 red, 2 green Power supply under voltage
5 red, 1 green
5 red, 2 green Current foldback
5 red, 3 green
6 red, 1 green
6 red, 2 green
7 red, 1 green Communication error
Position limit
Drive over temperature
Internal voltage out of range
Power supply over voltage
Over current
Communication Watchdog
Open winding
Bad encoder
NOTE: Items in bold italic represent drive faults, which automatically disable the motor.
Rev. 1.0
7/31/2019
40
Page 41
SSDC-R/C/IP Hardware Manual
6 Reference Materials
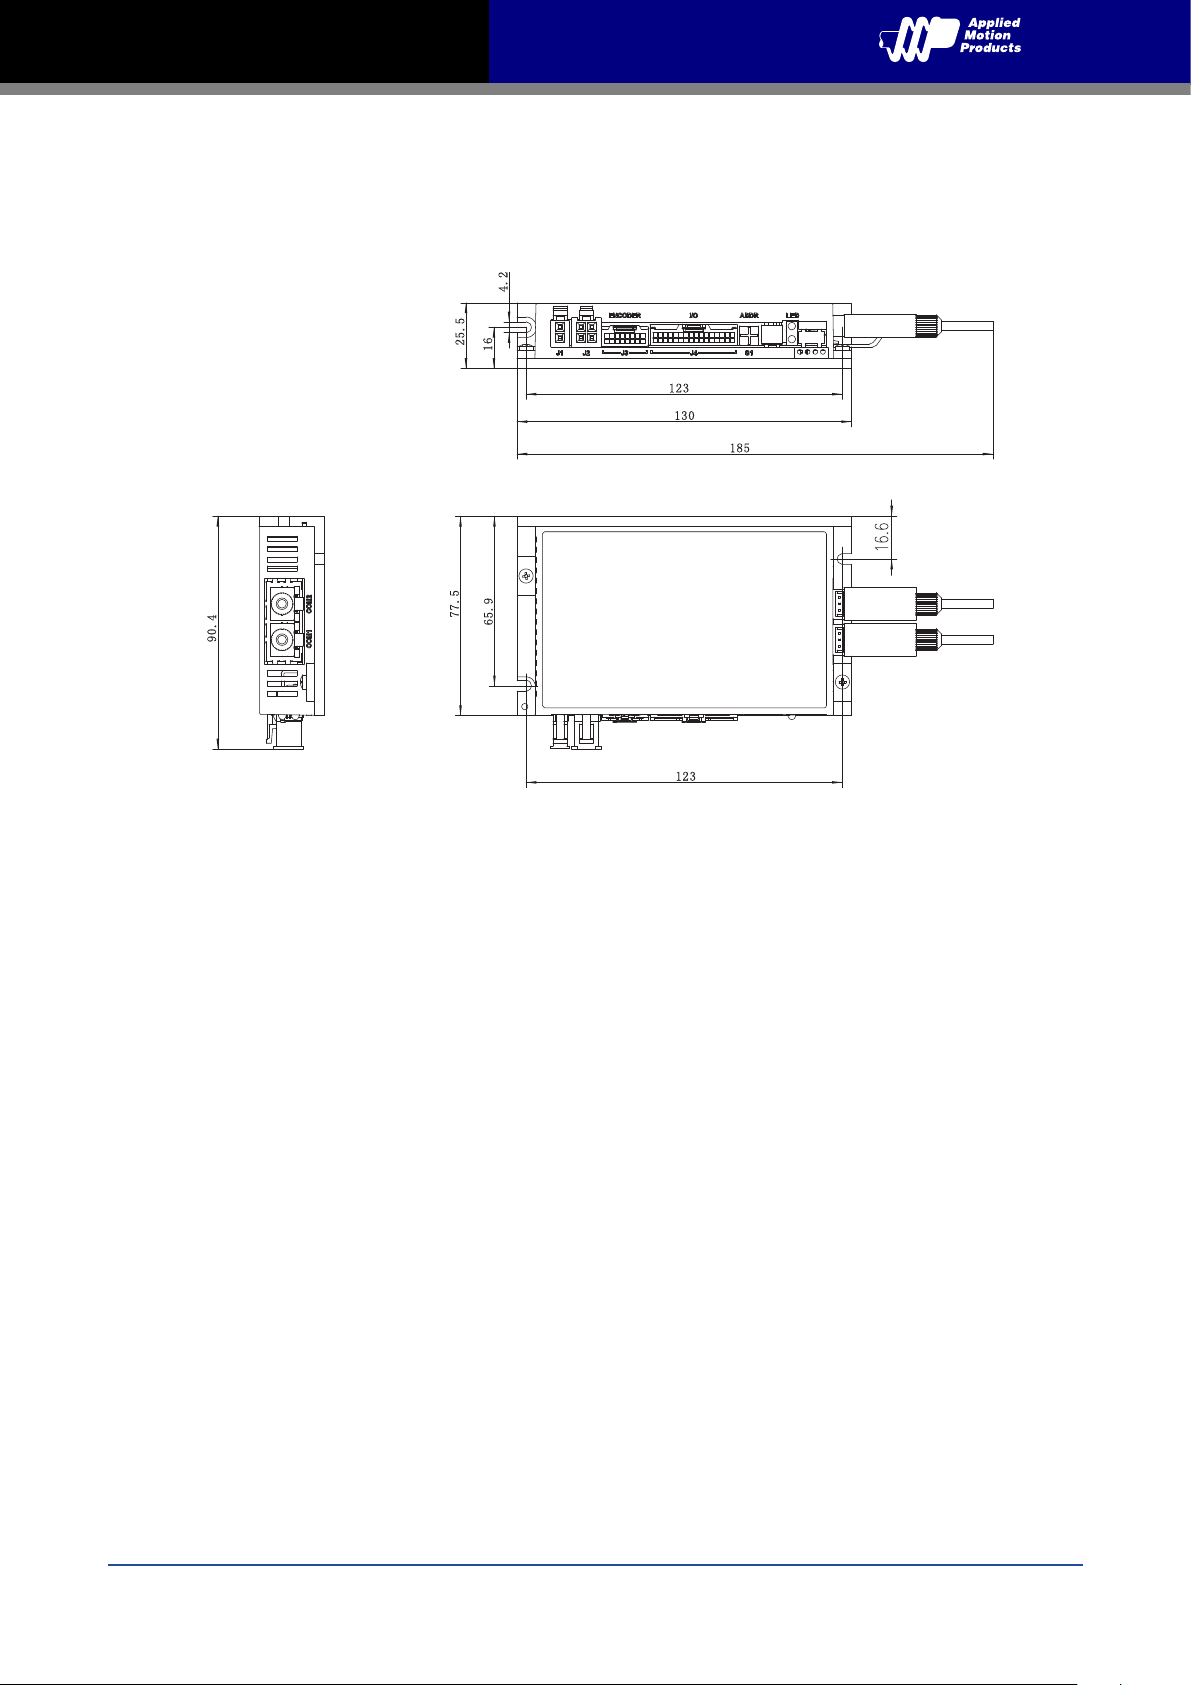
6.1 Drive Mechanical Outlines
(Unit:mm)
41
Rev. 1.0
7/31/2019
Page 42
SSDC-R/C/IP Hardware Manual
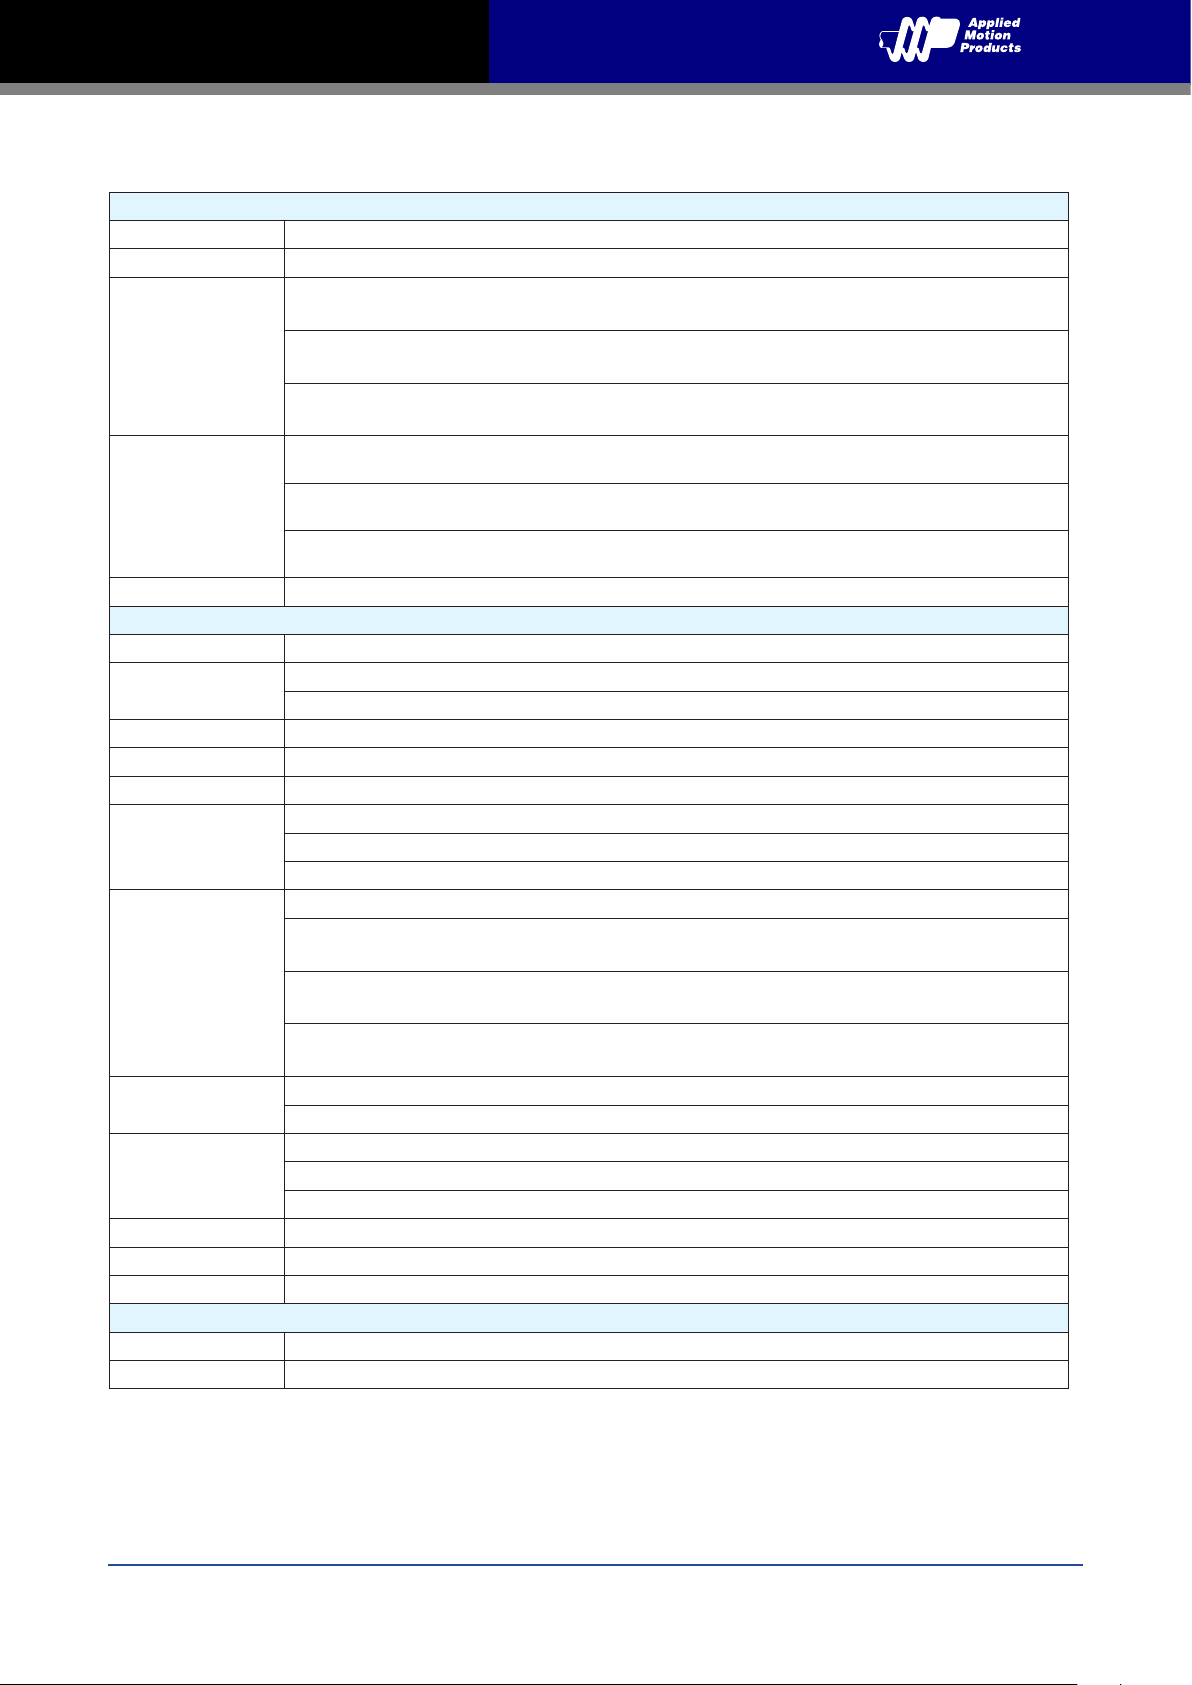
6.2 Technical Specifications
Power Amplifier
Amplifier Type Dual H-Bridge, 4 Quadrant
Current Control 4 state PWM at 20 KHz
SSDC03:
Continuous Current 3A max, Boost Current 4A max (1.5s), current limitation auto set-up by attached motor
Output Current
Power Supply
Protection Over-voltage, under-voltage, over-temp, motor/winding shorts (phase-to-phase, phase-to-ground)
Electronic Gearing Software selectable from 200 to 51200 steps/rev in increments of 2 steps/rev
Encoder Resolution
Speed Range Up to 3600rpm
Filters Digital input noise filter, Analog input noise filter, Smoothing filter, PID filter, Notch filter
Non-Volatile Storage Configurations are saved in FLASH memory on-board the DSP
Modes of Operation
Digital Inputs
Digital Outputs
Analog Inputs
Encoder Outputs/inputs Differential encoder outputs (A±, B±, Z±), 26C31 line driver, 20 mA sink or source max
+5V Output 4.8~5V, 100 mA max
Communication Dual-port RJ45 RS485/ CANopen/ Ethernet/ Ethernet/IP
Ambient Temperature 0 to 40°C (32 to 104°F) when mounted to a suitable heatsink
Ambient Humidity 90% Max., non-condensing
SSDC06:
Continuous Current 6A max, Boost Current 7.5A max (1.5s), current limitation auto set-up by attached motor
SSDC10:
Continuous Current 10A max, Boost Current 15A max (1.5s), current limitation auto set-up by attached motor
SSDC03:
External nominal 12 - 48 volt DC power supply required, Absolute maximum input voltage range 10 - 53 VDC
SSDC06:
External nominal 24 - 70 volt DC power supply required, Absolute maximum input voltage range 18 - 75 VDC
SSDC10:
External nominal 24 - 70 volt DC power supply required, Absolute maximum input voltage range 18 - 75 VDC
Controller
20000 counts/rev( for HT17/23/24/34SS-N motors)
4096 counts/rev( for HT11SS motors)
-R type: RS485 Mode, Q, Modbus/RTU
-C type: CANopen
-IP type: eSCL, Ethernet, Modbus/TCP, EtherNet/IP, Q
8 digital inputs
X1, X2: Optically isolated, differential, 5-24VDC; Minimum pulse width = 250ns,
Maximum pulse frequency = 2MHz;
X3, X4: Optically isolated, differential, 5-24VDC; Minimum pulse width = 100μs,
Maximum pulse frequency = 5KHz;
X5 ~ X8: Optically isolated, differential, 5-24VDC; Minimum pulse width = 100μs,
Maximum pulse frequency = 5KHz;
4 digital outputs
Y1 ~ Y4; Optically isolated, Open Collector, 30V/100 mA max, Maximum pulse frequency = 10KHz
2 analog inputs
Analog resolution: 12bit
Each input can accept a signal range of 0 to 5 VDC, ±5 VDC, 0 to 10 VDC or ±10 VDC
Physical
Rev. 1.0
7/31/2019
42
Page 43
SSDC-R/C/IP Hardware Manual
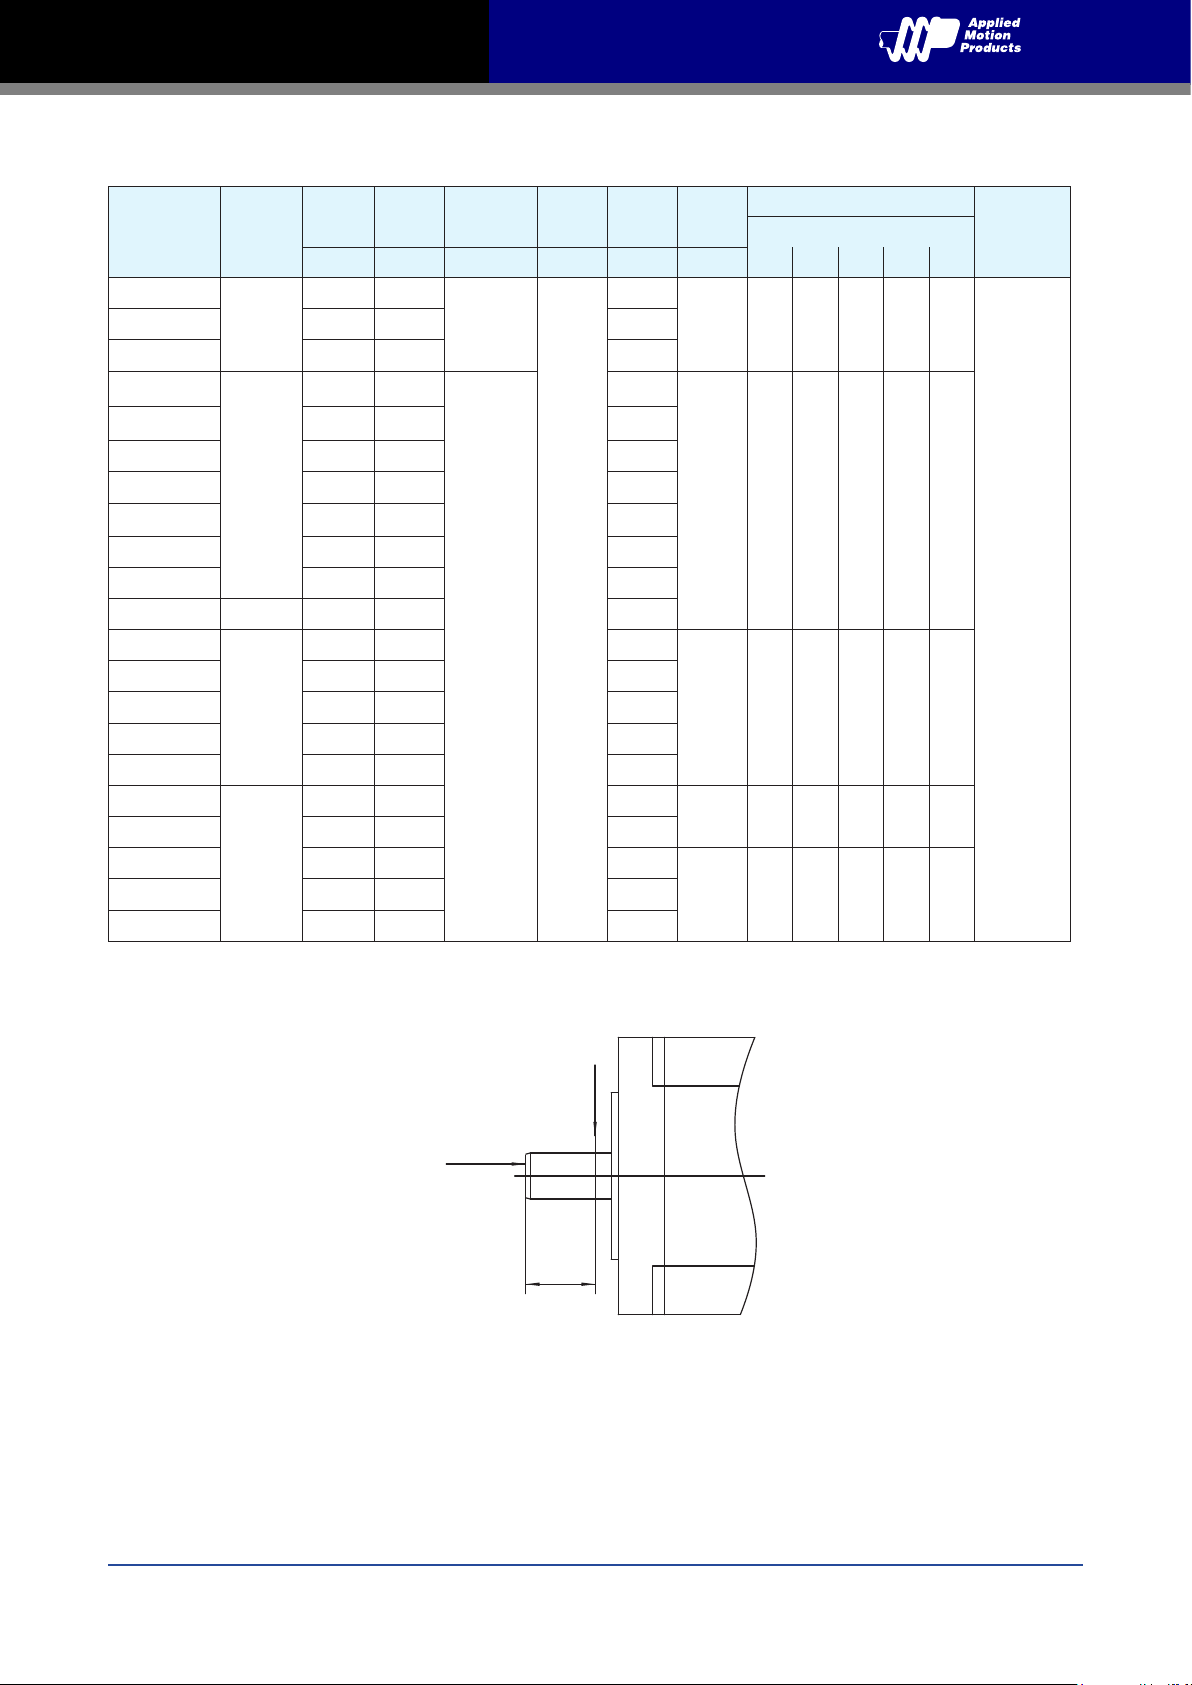
6.3 Recommended Motors
Motor Part
Number
HT11-SS1DMA
HT11-SS2DMA 0.08 12 168
HT11-SS3DMA 0.125 18 218
HT17-SS1DGB
HT17-SS1DGA 0.3 38 390
HT17-SS2DGB 0.5 57 440
HT17-SS2DGA 0.5 57 440
HT17-SS3DGB 0.6 82 520
HT17-SS3DGA 0.6 82 520
HT17-SS4DGB 0.75 123 760
HT17-SS4DGA SSDC10 0.75 123 760
HT23-SS2DGB
HT23-SS2DGA 0.9 260 850
HT23-SS3DGB 1.5 460 1250
HT23-SS3DGA 1.5 460 1250
HT23-SS4DGA 2.5 365 1090
HT24-SS3DGB
HT24-SS3DGA 2.5 900 1650
HT34-SS1DGA 3.5 915 2000
HT34-SS5DGA 8.0 2200 4200
Matching
Drive
SSDC03
SSDC03
SSDC10
SSDC10
Holding
Torque
N-m G-cm2counts/rev RPM g mm 0 5 10 15 20
0.065 9
0.3 38
0.9 260 850
2.5 900 1650
Rotor
Inertia
Encoder
Resolution
4096
20000
Max.
Speed
3600
Mass
118
390
Frame
Size
28 20 25 34 52 -
42 35 44 58 85 -
56 63 75 95 130 190
60 90 100 130 180 270
86 260 290 340 390 480HT34-SS3DGA 6.0 1480 3100
Permissible Shaft Load (N)
Distance (L) from shaft end (mm)
Permissible
Thrust Load
Less than the
motor mass
Thrust Load
Overhung Load
L
43
Rev. 1.0
7/31/2019
Page 44
SSDC-R/C/IP Hardware Manual
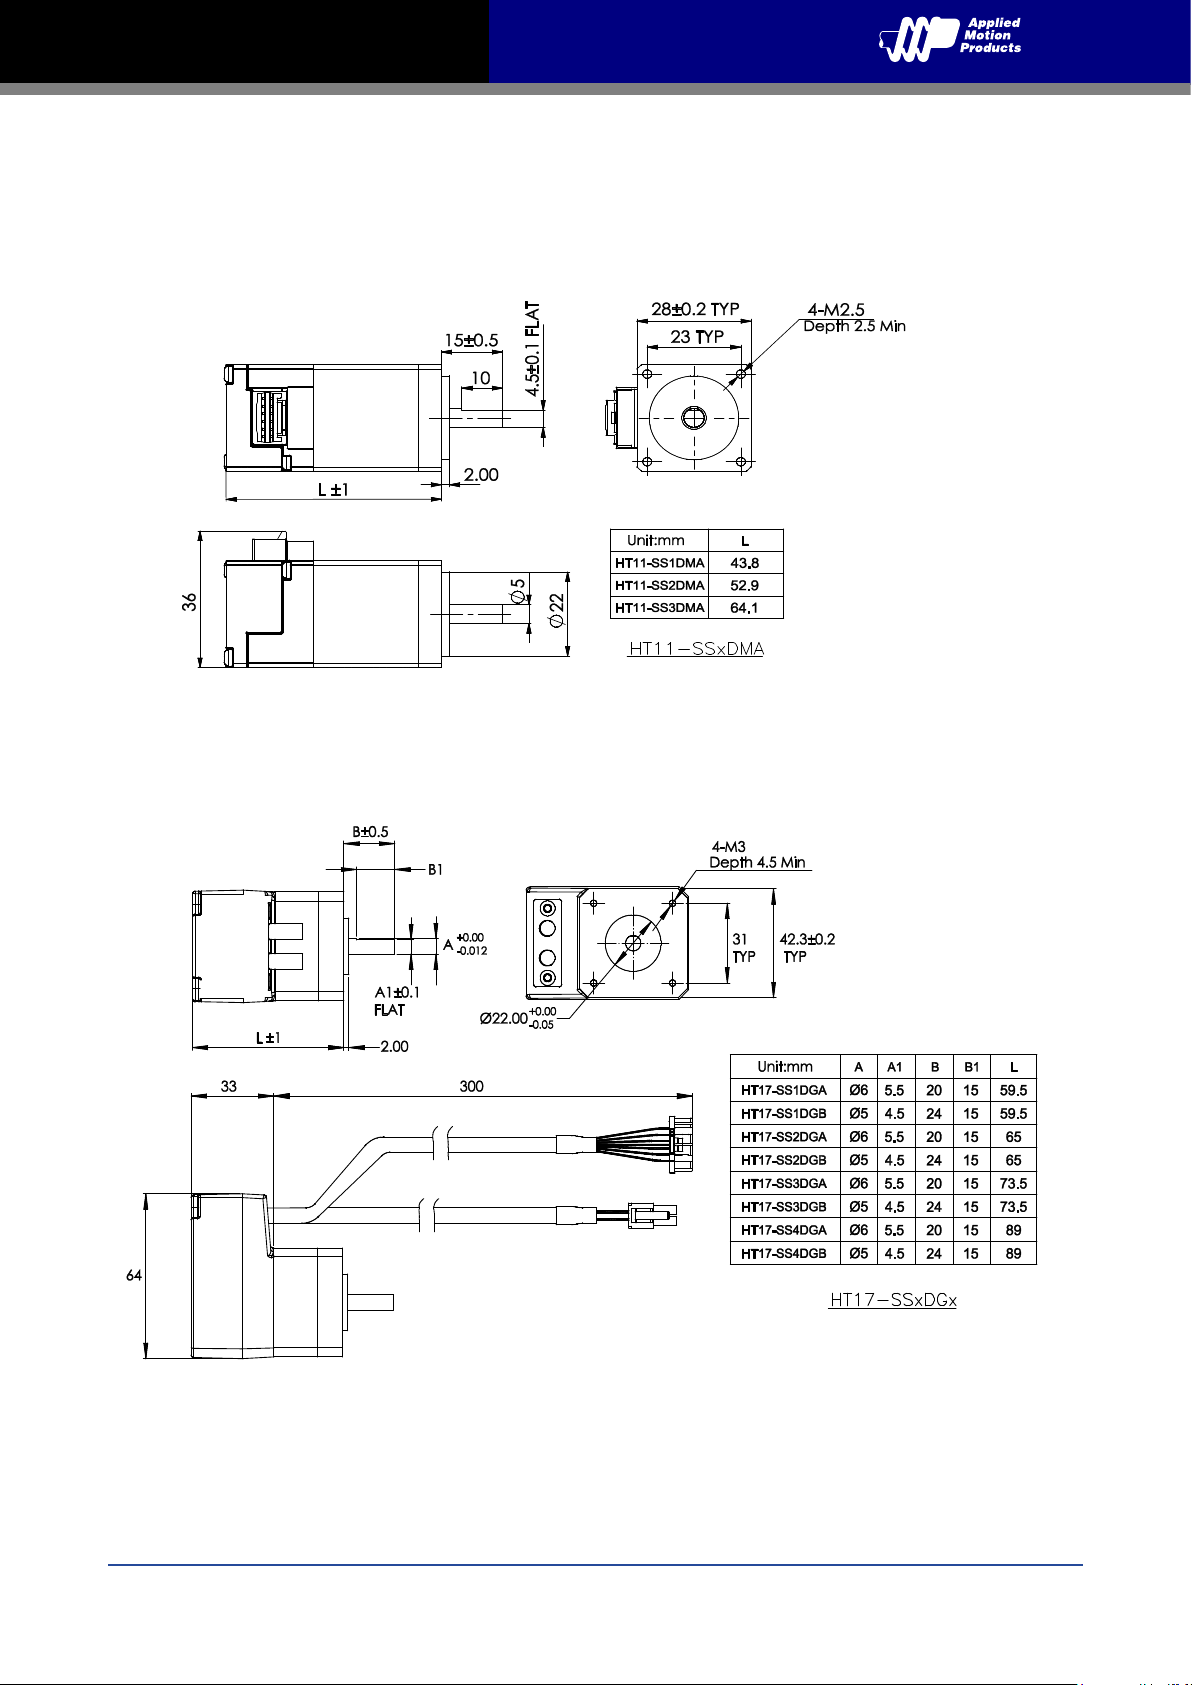
6.4 Mechanical Dimension
HT11-SS (Unit: mm)
HT17-SS (Unit: mm)
Rev. 1.0
7/31/2019
44
Page 45
SSDC-R/C/IP Hardware Manual
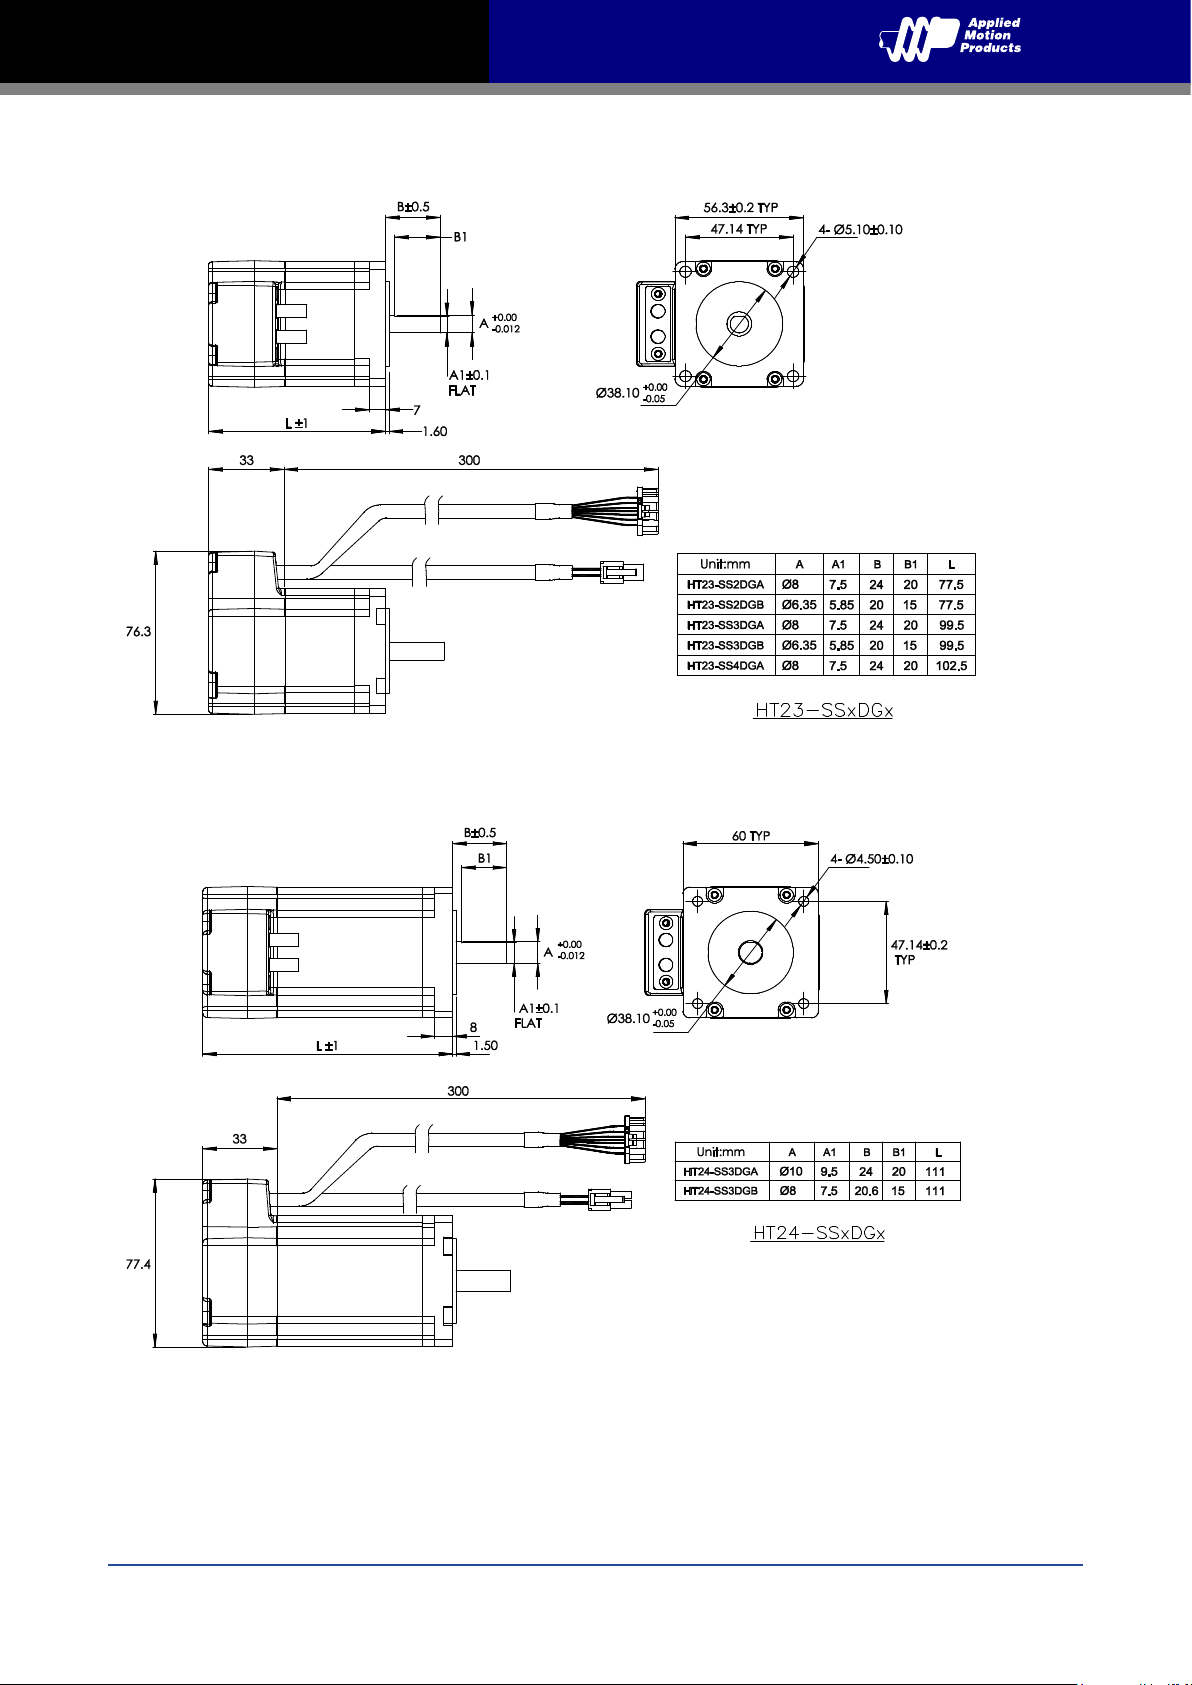
HT23-SS (Unit: mm)
HT24-SS (Unit: mm)
45
Rev. 1.0
7/31/2019
Page 46
SSDC-R/C/IP Hardware Manual
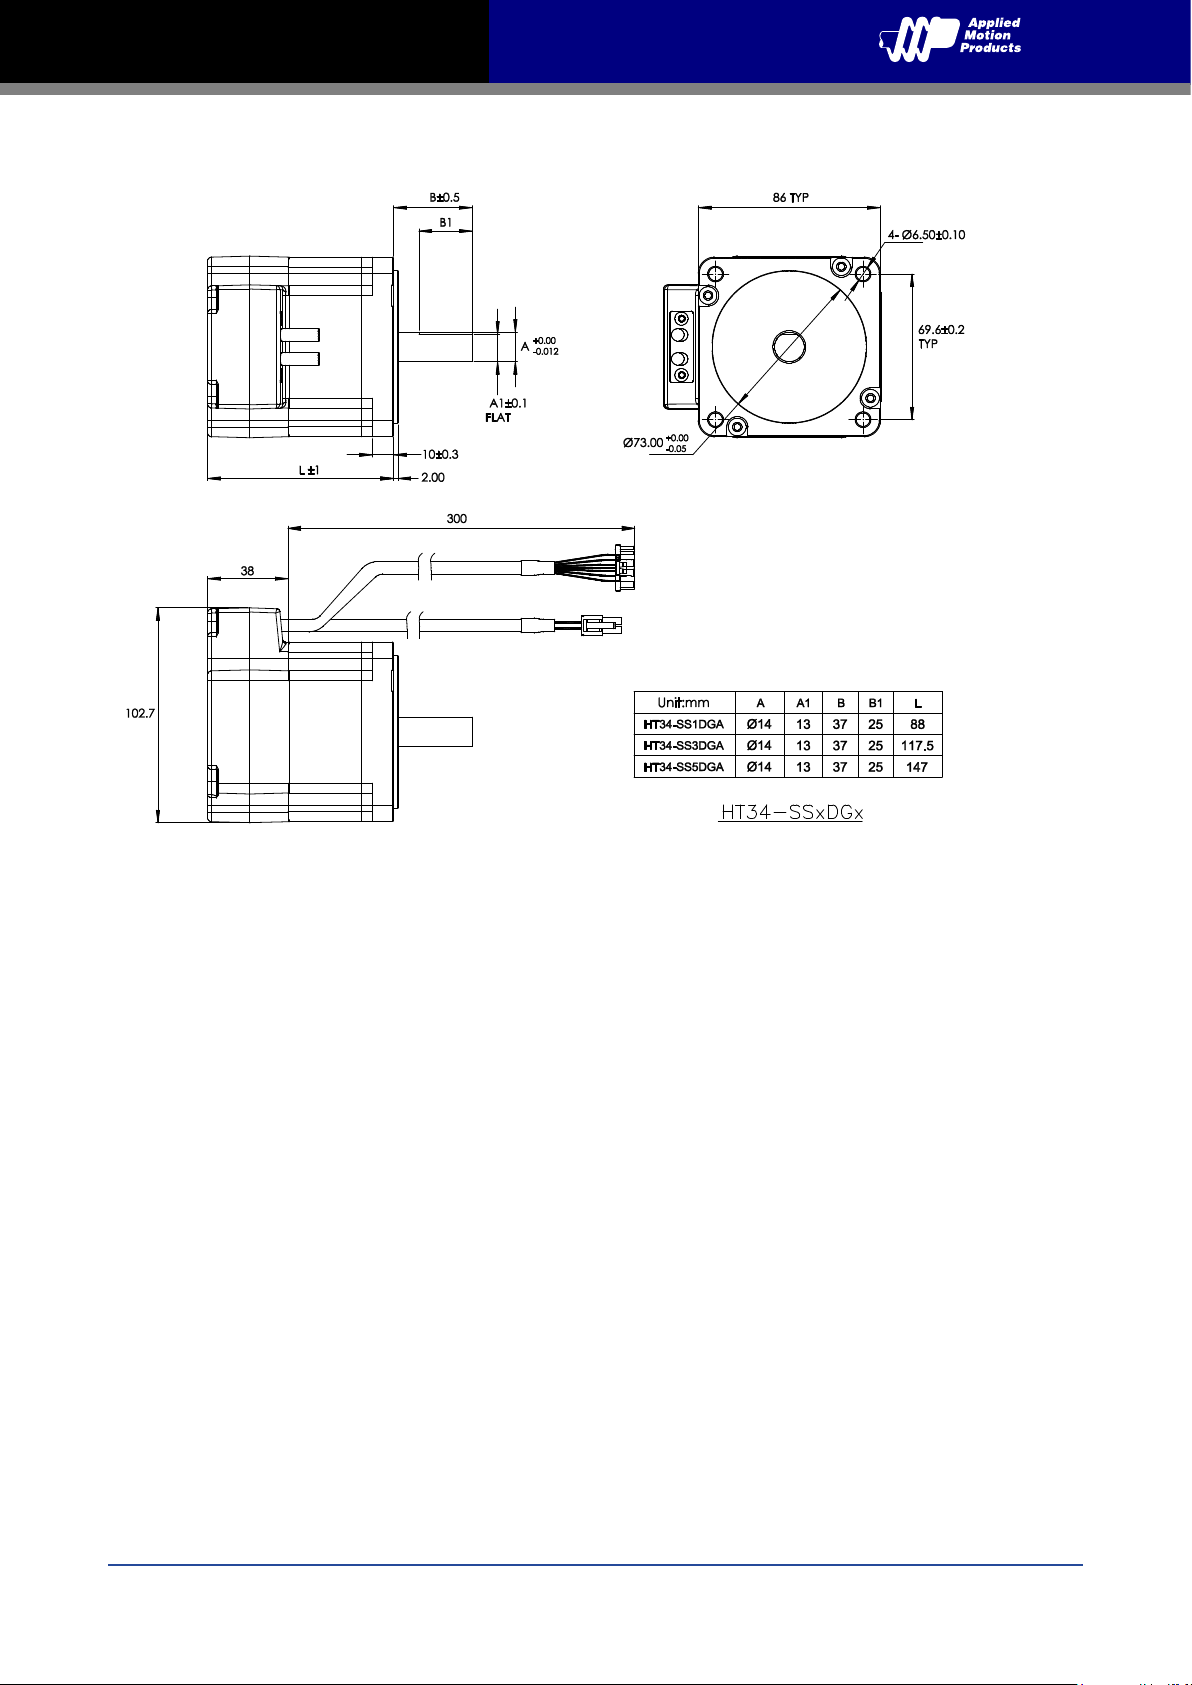
HT34-SS (Unit: mm)
Rev. 1.0
7/31/2019
46
Page 47
SSDC-R/C/IP Hardware Manual
Torque(oz-in)
0
2.8
5.7
11.3
14.2
8.5
0
20
40
60
80
100
0 10 20 30 40 50
HT11-SS1DM_
24V
24V
Continuous
Boost
Torque(mN·m)
Speed(rps)
Torque(oz-in)
0
4.2
8.5
17
21.2
12.7
0
30
60
90
120
150
0 10 20 30 40 50
HT11-SS2DM_
24V
24V
Continuous
Boost
Torque(mN·m)
Speed(rps)
Torque(oz-in)
0
5.6
11
22.7
28.3
17
0
40
80
120
160
200
0 10 20 30 40 50
HT11-SS3DM_
24V
24V
Continuous
Boost
Torque(mN·m)
Speed(rps)
Torque(oz-in)
0
14.2
28.3
56.6
42.5
0
0.1
0.2
0.3
0.4
0 10 20 30 40 50
HT17-SS1DG_
24V 48V
24V 48V
Continuous
Boost
Torque(N·m)
Speed(rps)
Torque(oz-in)
0
14.2
28.3
56.6
70.8
85
42.5
0
0.1
0.2
0.3
0.4
0.5
0.6
0 10 20 30 40 50
HT17-SS2DG_
24V 48V
24V 48V
Continuous
Boost
Torque(N·m)
Speed(rps)
Torque(oz-in)
0
14.2
28.3
56.6
70.8
85
99
42.5
0
0.1
0.2
0.3
0.4
0.5
0.6
0.7
0 10 20 30 40 50
HT17-SS3DG_
24V 48V
24V 48V
Continuous
Boost
Torque(N·m)
Speed(rps)
Torque(oz-in)
0
28.3
56.6
113.3
141.6
85
0
0.2
0.4
0.6
0.8
1.0
0 10 20 30 40 50
HT17-SS4DG_
24V 48V
24V 48V
Continuous
Boost
Torque(N·m)
Speed(rps)
Torque(oz-in)
0
43
85
128
170
212
0
0.3
0.6
0.9
1.2
1.5
0 10 20 30 40 50
24V 48V 70V
24V 48V 70V
HT23-SS2DG_
Continuous
Boost
Torque(N·m)
Speed(rps)
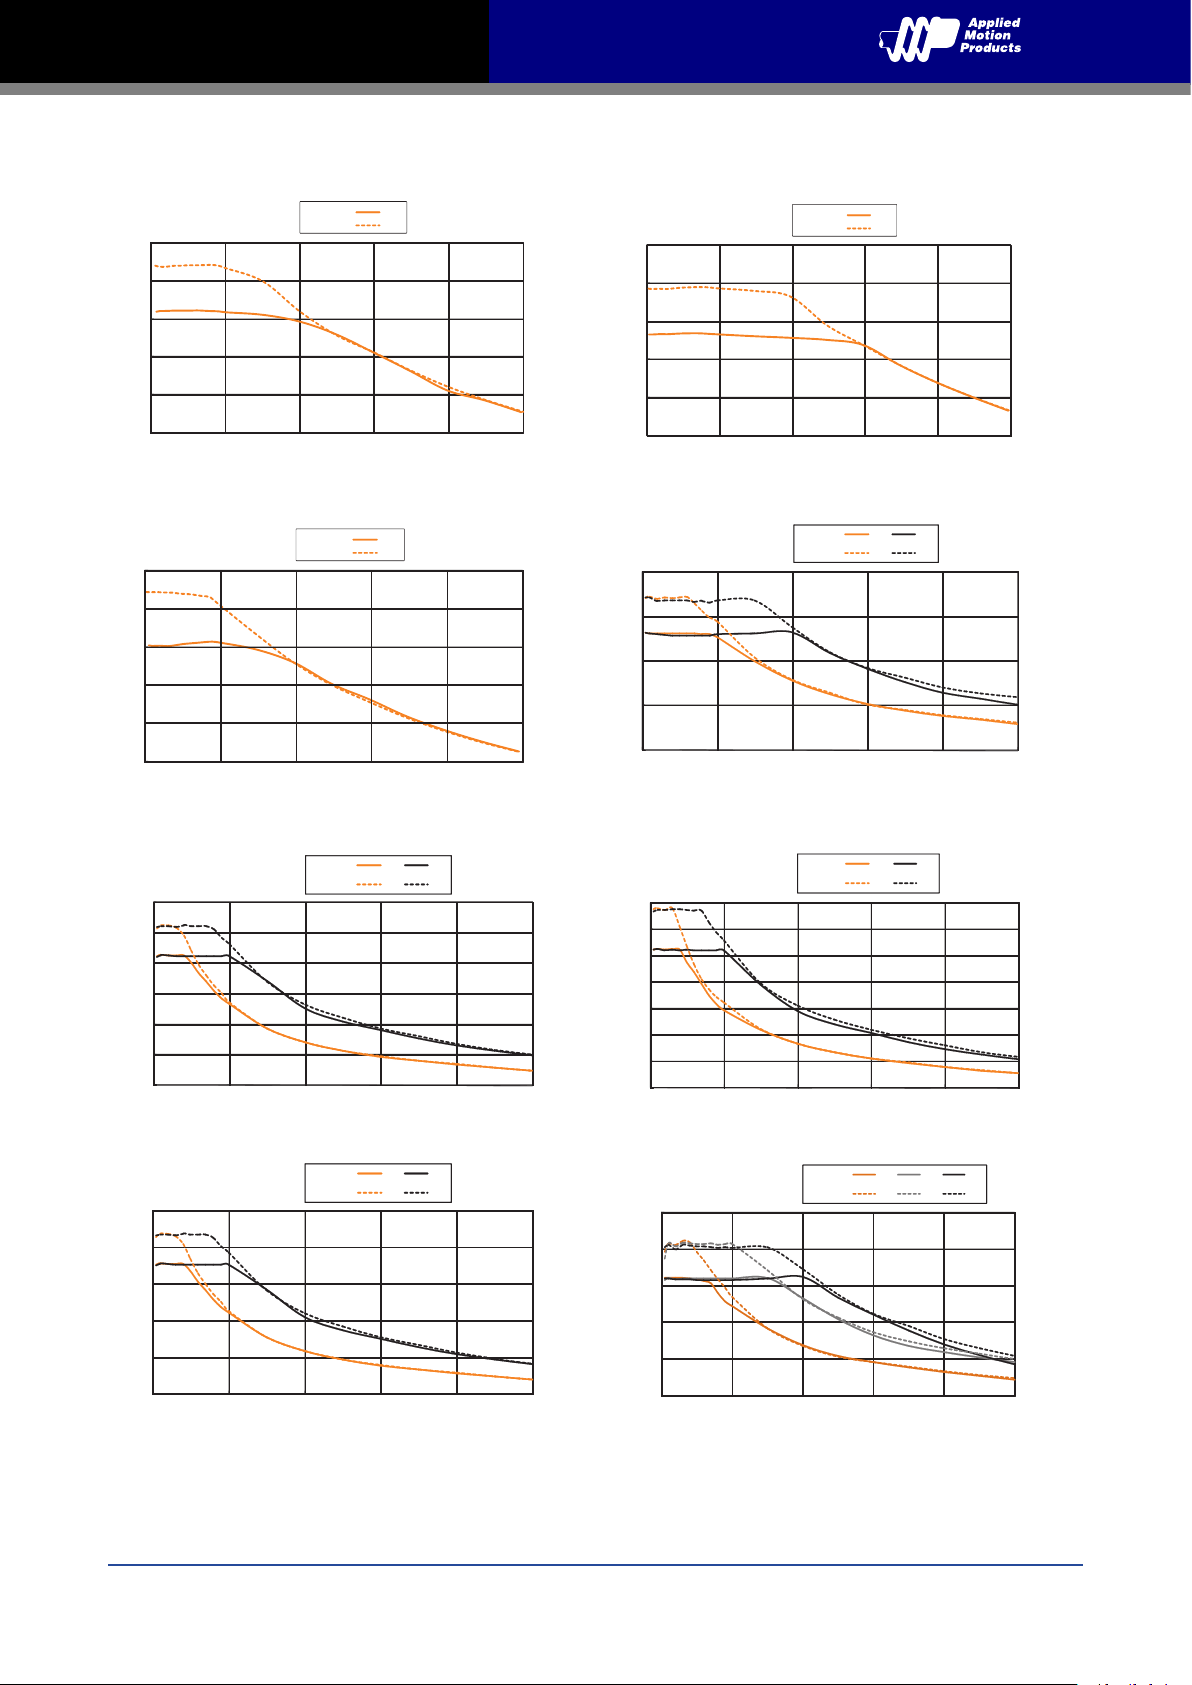
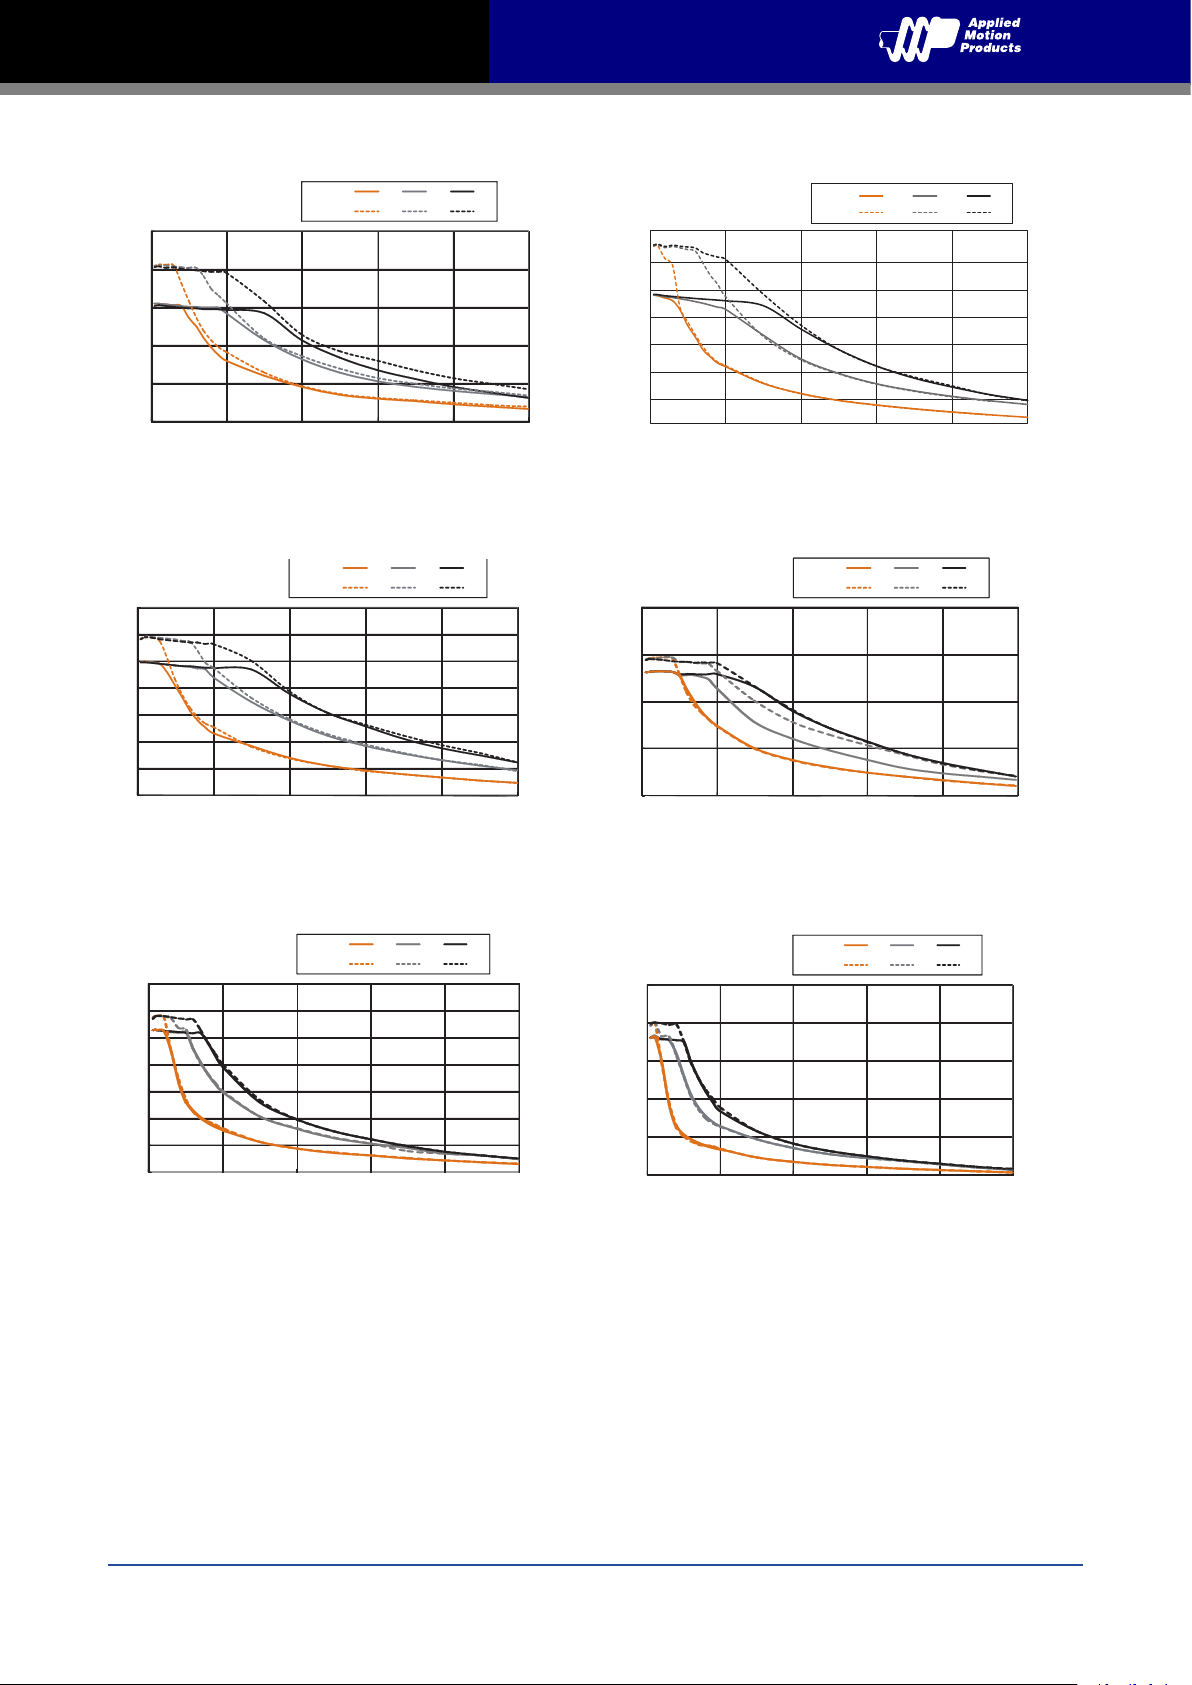
6.5 Torque Curves
47
Rev. 1.0
7/31/2019
Page 48
SSDC-R/C/IP Hardware Manual
Torque(oz-in)
0
283
566
850
1133
1416
0
2.0
4.0
6.0
8.0
10
0 10 20 30 40 50
24V 48V 70V
24V 48V 70V
HT34-SS5DG_
Continuous
Boost
Torque(N·m)
Speed(rps)
Torque(oz-in)
Torque(N·m)
0
1.0
2.0
3.0
4.0
5.0
6.0
7.0
0
142
283
425
566
708
850
991
0 10 20 30 40 50
24V 48V 70V
24V 48V 70V
HT34-SS3DG_
Continuous
Boost
Speed(rps)
0 0
1.0
2.0
3.0
4.0
0 10 20 30 40 50
HT34-SS1DG_
24V 48V 70V
24V 48V 70V
Continuous
Boost
142
283
425
567
Torque(oz-in)
Speed(rps)
Torque(N·m)
Torque(oz-in)
0
71
142
212
283
496
354
425
0
0.5
1
1.5
2
2.5
3
3.5
0 10 20 30 40 50
24V 48V 70V
24V 48V 70V
HT24-SS3DG_
Continuous
Boost
Torque(N·m)
Speed(rps)
Torque(oz-in)
0
70.8
141.6
212.4
283.2
495.7
354
424.9
0
0.5
1
1.5
2
2.5
3
3.5
0 10 20 30 40 50
HT23-SS4DG_
24V 48V 70 V
24V 48V 70 V
Continuous
Boost
Torque(N·m)
Speed(rps)
Torque(oz-in)
0
71
142
212
283
354
0
0.5
1
1.5
2
2.5
0 10 20 30 40 50
24V 48V 70V
24V 48V 70V
HT23-SS3DG_
Continuous
Boost
Torque(N·m)
Speed(rps)
Rev. 1.0
7/31/2019
48
Page 49
SSDC-R/C/IP Hardware Manual
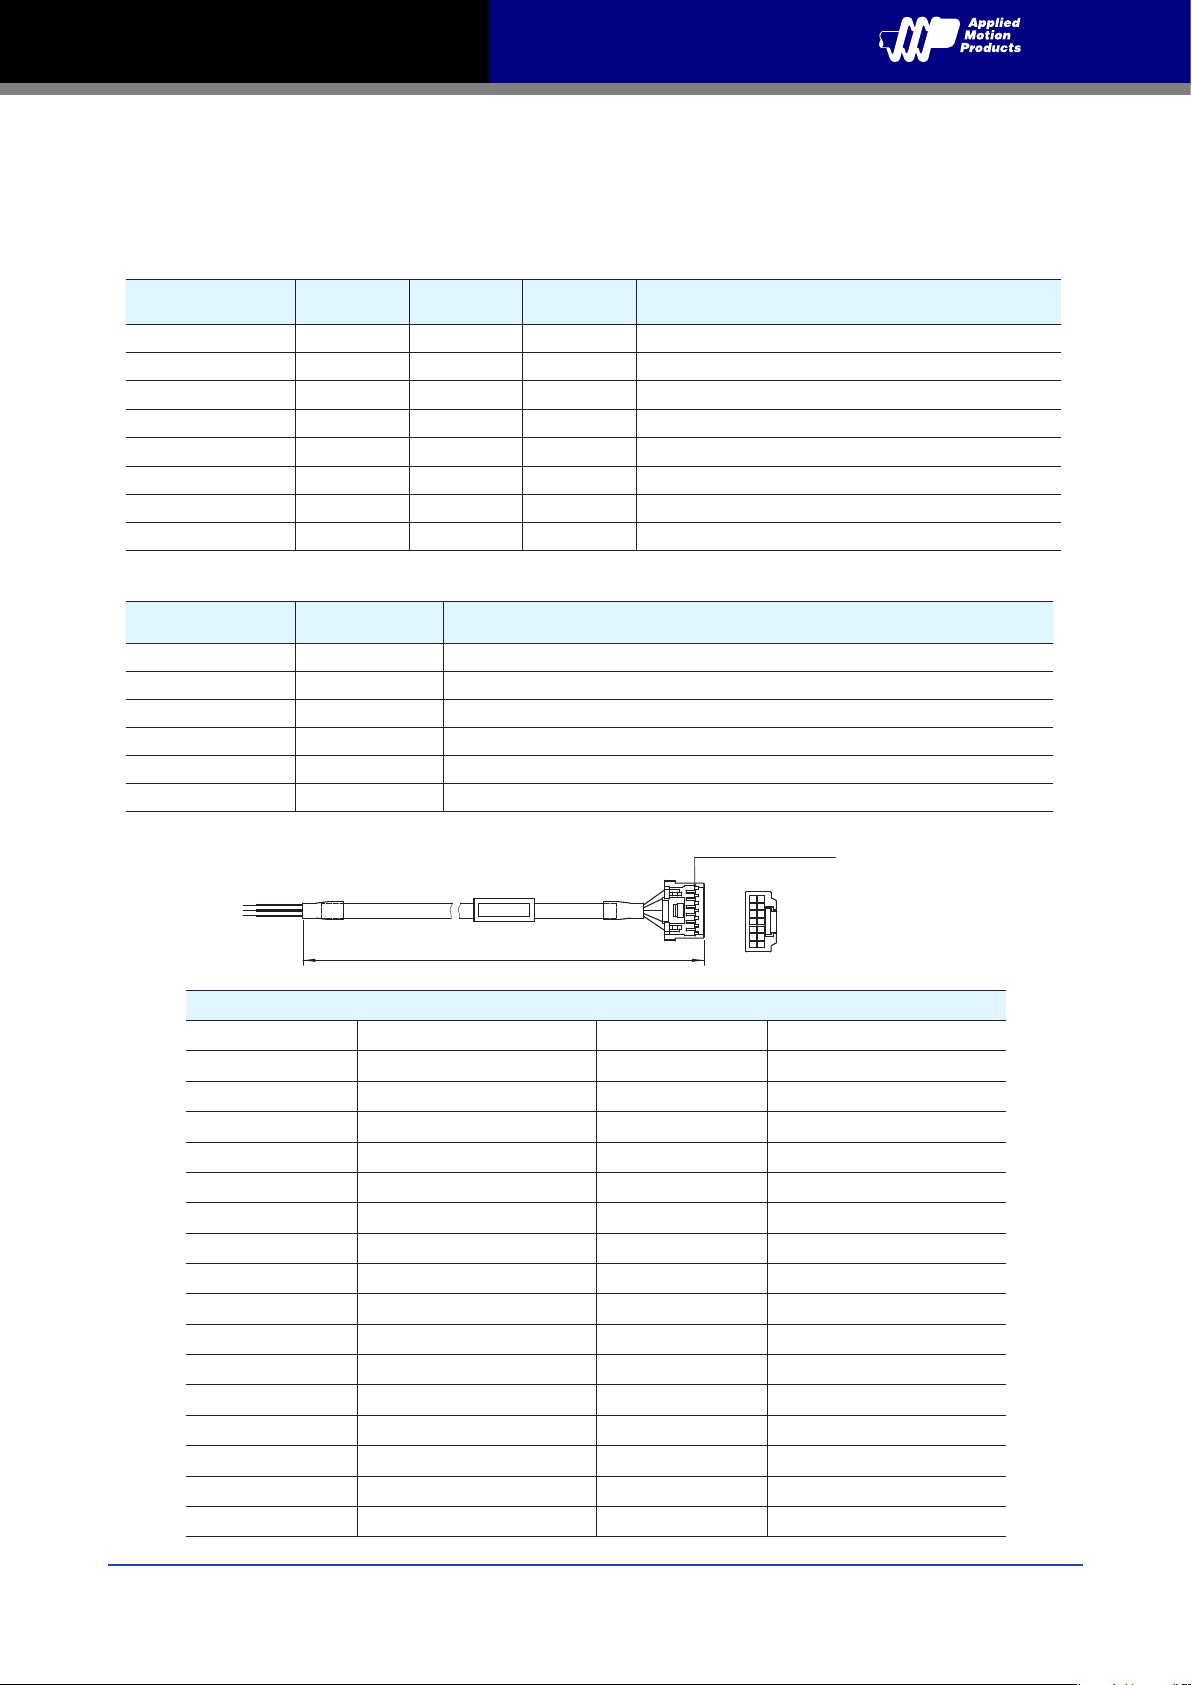
501646-3200(Molex)
7 Accessories
7.1 Standard Accessories (Included)
• -D/IP Type
Model Qty Catagory Vendor Description
1 Cable / Power supply cable
CAT5 Ethernet 1 Cable / 0.3m network cable
1 Screwdriver / Screwdriver
39-01-3048 1 Housing Molex Motor connector housing J2
501646-1600 1 Housing Molex Encoder connector housing J3
501646-3200 1 Housing Molex I/O connector housing J4
39-00-0038 5 Crimp Molex Motor connector crimp
501648-1000 52 Crimp Molex Encoder & I/O connector crimp
7.2 Optional Accessories (Sold Separately)
Model Catagory Description
RC880 Regeneration Clamp Regeneration Clamp
3004-340 Cable I/O Cable
3004-408-xM Cable Extended motor cable, For SSDC drive and HT11SS motor
3004-403-xM Cable Extended motor cable, For SSDC drive and HT17/23/24/34SS motor
3004-339-xM Cable Extended encoder cable, For SSDC drive and HT11SS motor
3004-338-xM Cable Extended encoder cable, For SSDC drive and HT17/23/24/34SS motor
7.2.1 I/O Cable
L
Housing:
Crimp: 501648-1000(Molex)
D
31
32
J1
1 2
Wiring Diagram
PIN (J1) Color (Signal) PIN (J1) Color (Signal)
1 Blue/White (X1+) 17 NC
2 Blue/Black (X1-) 18 NC
3 Green/White (X2+) 19 Brown/White (Y1+)
4 Green/Black (X2-) 20 Brown/Black (Y1-)
5 Red (X3+) 21 Gray/White (Y2+)
6 Orange (X3-) 22 Gray/Black (Y2-)
7 Blue (X4+) 23 Purple/White (Y3+)
8 Purple (X4-) 24 Purple/Black (Y3-)
9 Yellow (X5) 25 Pink (Y4+)
10 Green (X6) 26 Yellow/Green (Y4-)
11 Brown (X7) 27 Red/White (AOUT+)
12 Gray (X8) 28 Red/Black (AOUT-)
13 Shield 29 Orange/White (BOUT+)
14 White (XCOM) 30 Orange/Black (BOUT-)
15 Black (GND) 31 Yellow/White (ZOUT+)
16 NC 32 Yellow/Black (ZOUT-)
49
Rev. 1.0
7/31/2019
Page 50
SSDC-R/C/IP Hardware Manual
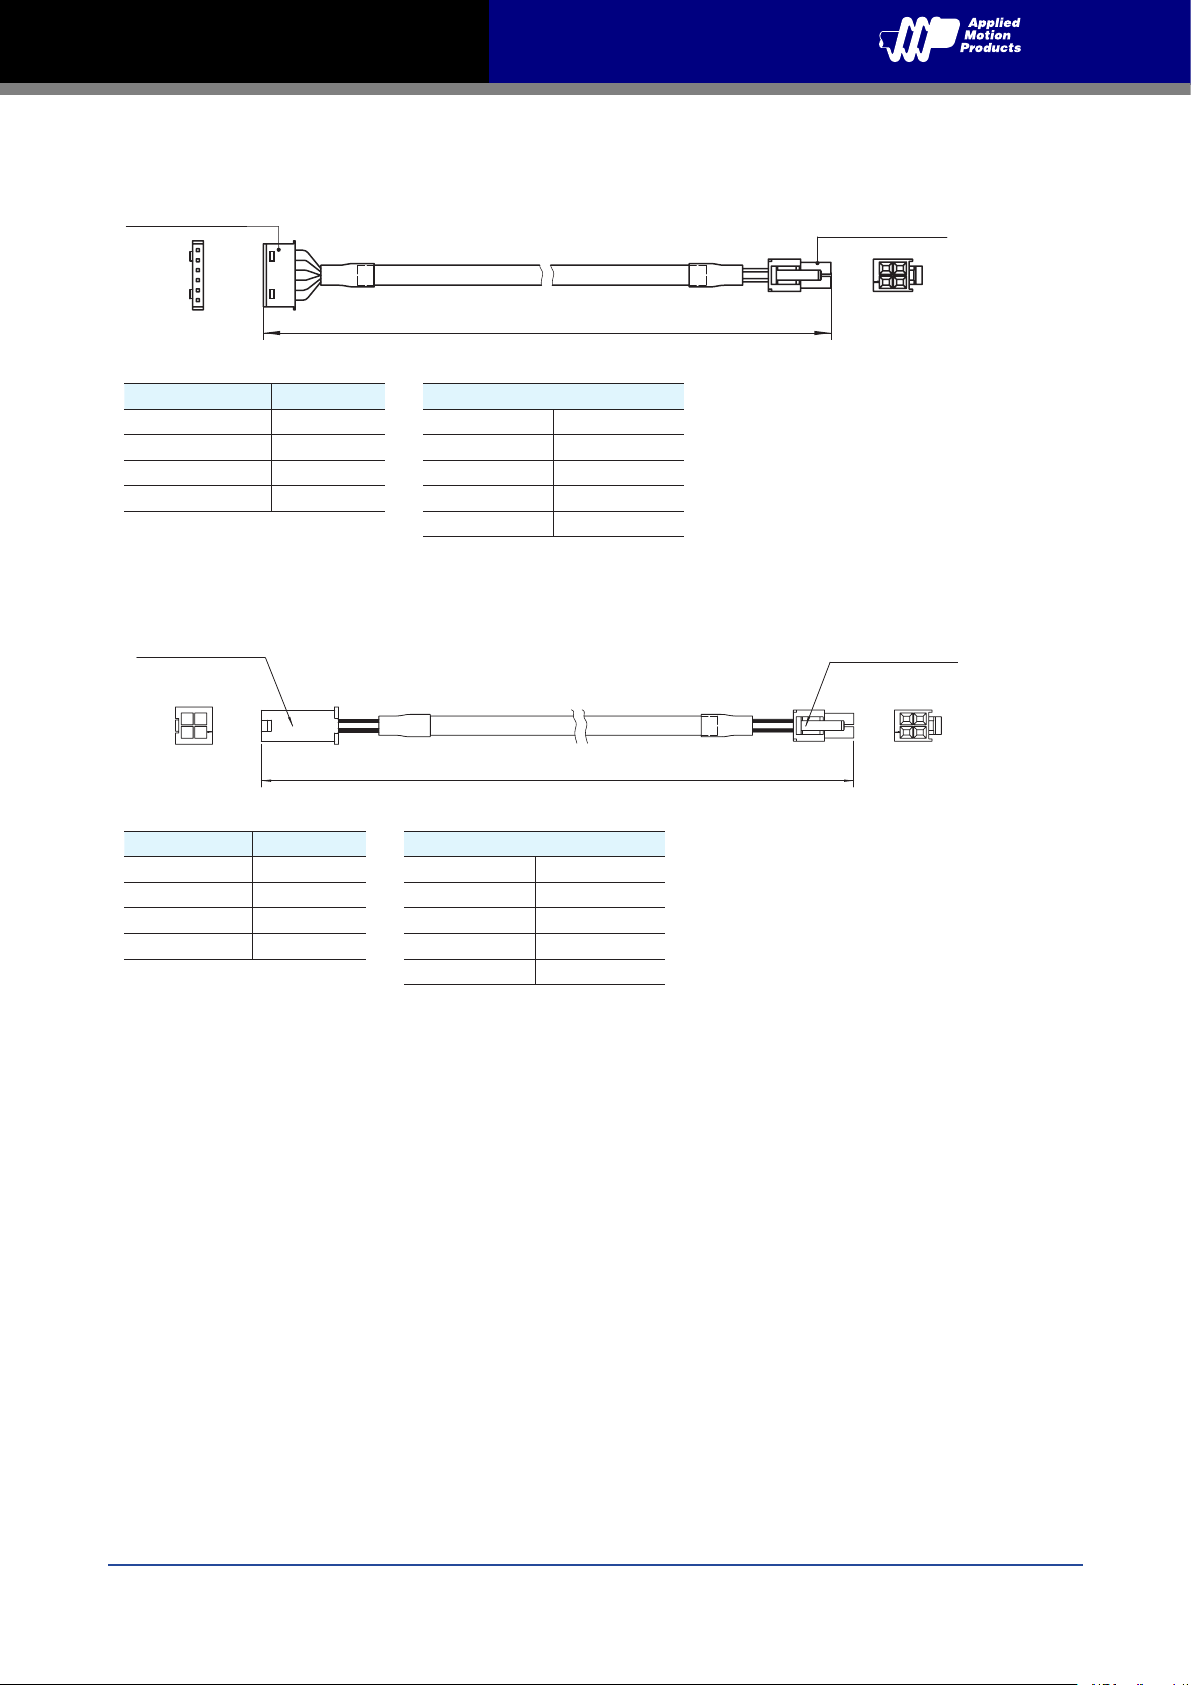
7.2.2 Extended motor cable (For SSDC drive and HT11SS motor)
Housing:51065-0600(Molex)
Crimp:50212-8000(Molex)
J1
6
1
L
P/N Length(L) Wiring Diagram
3004-408-1M 1M
PIN(J1) Color (Signal)
3004-408-3M 3M 1 Blue(B-)
3004-408-5M 5M 3
3004-408-10M 10M 4
6
Red(B+)
Green(A-)
Black(A+)
7.2.3 Extended motor cable (For SSDC drive and HT17/23/24/34SS motor)
Housing:39-01-3049(Molex)
Crimp:39-00-0040(Molex)
2
4
J1
1
3
L
39-01-3048(Molex)
Housing:
Crimp:39-00-0038(Molex)
2
1
Housing:39-01-3048(Molex)
Crimp:39-00-0038(Molex)
4
3
2
1
J2
4
J2
3
P/N Length(L) Wiring Diagram
3004-403-1M 1M PIN(J1) Color (Signal)
3004-403-3M 3M 1 Blue(B-)
3004-403-5M 5M 2 Red(B+)
3004-403-10M 10M 3 Green(A-)
4 Black(A+)
Rev. 1.0
7/31/2019
50
Page 51
SSDC-R/C/IP Hardware Manual
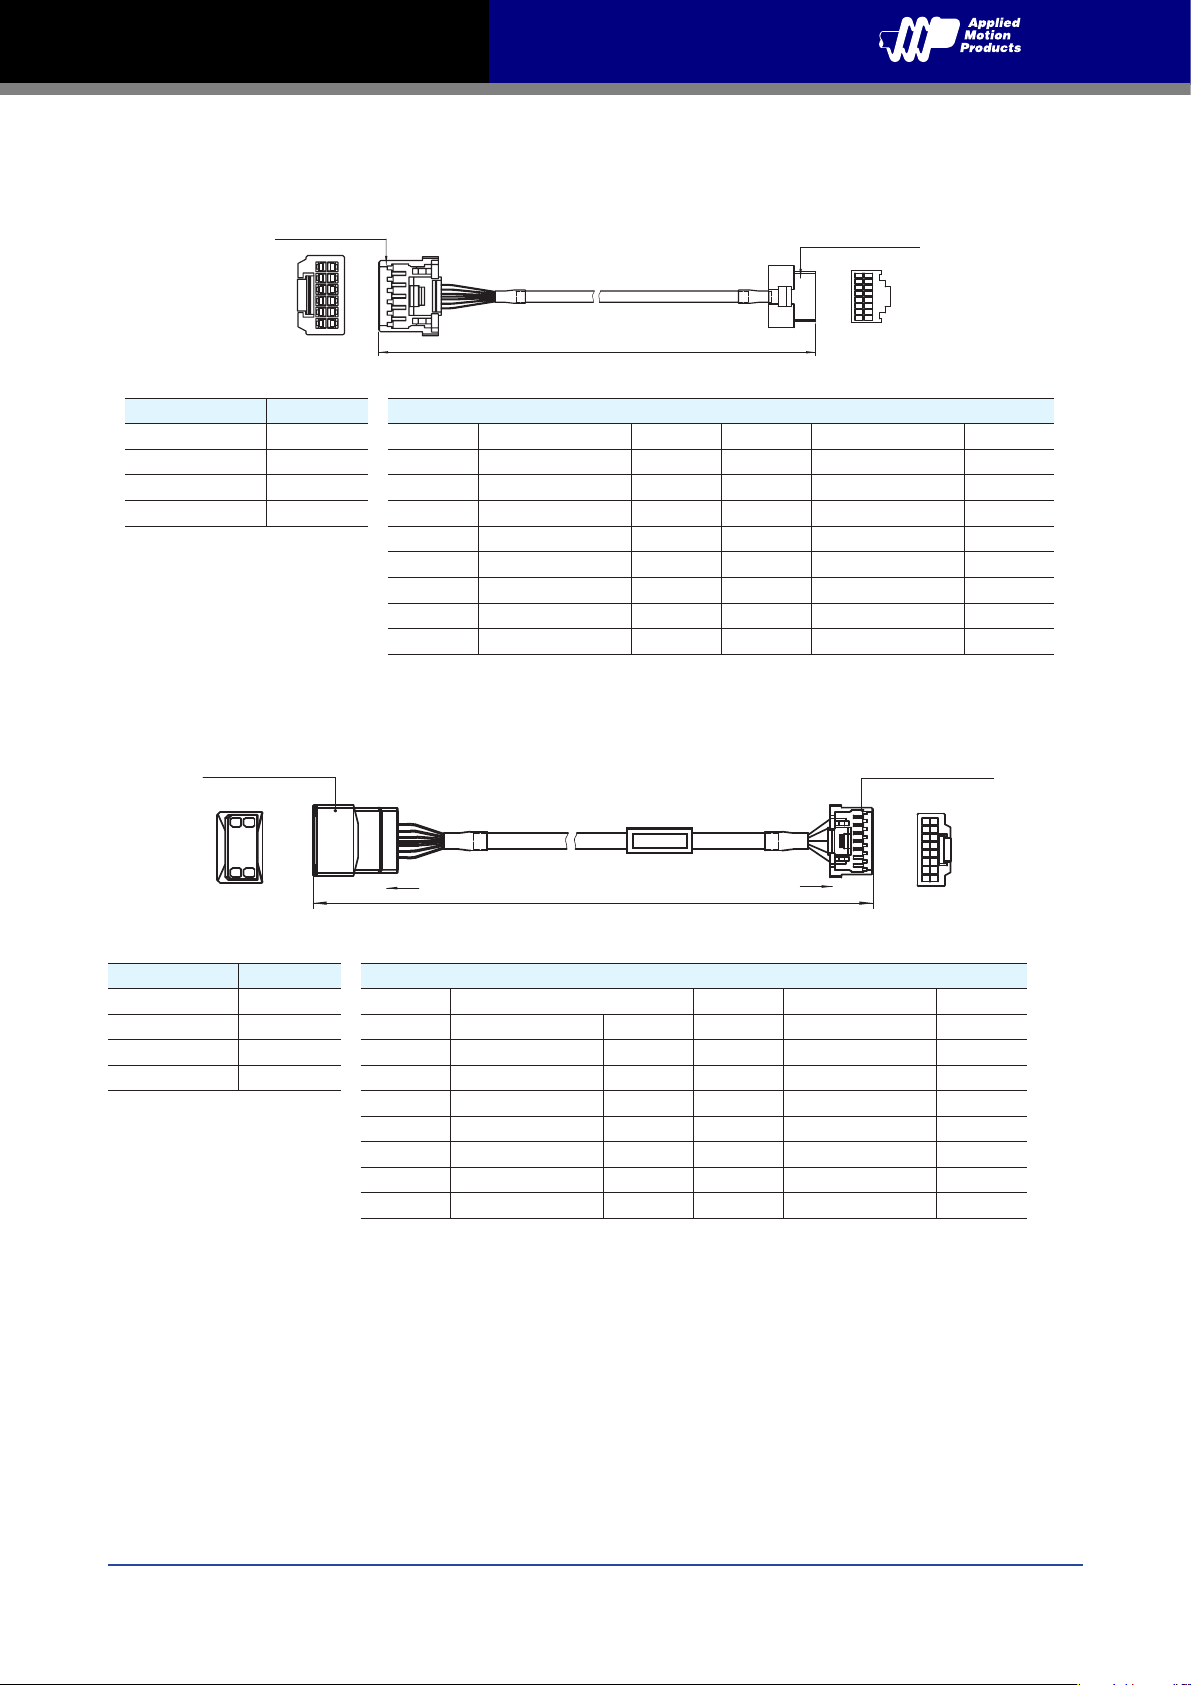
L
7.2.4 Extended encoder cable (For SSDC drive and HT11 motor)
Housing:501646-1200(Molex)
Crimp:501648-1000(Molex)
2
J1
12
1
11
J21DF-16V-KX-L(JST)
Housing:
Crimp:SJ2F-002GF-P1.0(JST)
B
A
1
1
J2
88
P/N Length(L) Wiring Diagram
3004-338-1M 1M PIN (J1) Color (Signal) PIN (J2) PIN (J1) Color (Signal) PIN (J2)
3004-338-3M 3M A9 Blue (A+) 1 B5 Shield 10
3004-338-5M 5M B9 Blue/Black (A-) 2 A4 Brown (U+) 11
3004-338-10M 10M A8 Green (B+) 3 B4 Brown/Black (U-) 12
B8 Green/Black (B-) 4 A3 Gray (V+) 13
A7 Yellow (Z+) 5 B3 Gray/Black (V-) 14
B7 Yellow/Black (Z-) 6 A2 White (W+) 15
A6 Red (+5V) 7 B2 White (W+) 16
B6 Black (GND) 8
7.2.5 Extended encoder cable (For SSDC drive and HT17/23/24/34SS motor)
Housing: 1-1903130-0(TYCO)
Crimp: 1903120-1(TYCO)
C
B1
J1
B10
A1
A10
C
L
D
Housing: 501646-1600(Molex)
Crimp: 501648-1000(Molex)
D
15
1 2
16
J2
P/N Length(L) Wiring Diagram
3004-339-1M 1M PIN(J1) Color (Signal) PIN(J2) PIN(J1) Color (Signal) PIN(J2)
3004-339-3M 3M 10 Blue(A+) 1 Brown(U+)
3004-339-5M 5M 9 Blue/Black(A-) 2 Brown/Black(U-)
3004-339-10M 10M 8 Green(B+) 3 Gray(V+)
7 Green/Black(B-) 4 Gray/Black(V-)
6 Yellow(Z+) 5 1 White(W+) 15
5 Yellow/Black(Z-) 6 2 White/Black(W-) 16
3 Red(+5V) 7 12 Shield 10
4 Black(GND) 8
51
Rev. 1.0
7/31/2019
Page 52
SSDC-R/C/IP Hardware Manual
8 Contacting Applied Motion Products
Rev. 1.0
7/31/2019
404 Westridge Dr.
Watsonville, CA 95076 USA
1-800-525-1609
www.applied-motion.com
52
 Loading...