

Page 1
FM Series
GPS Receiver Module
Data Guide
Page 2
Warning: Some customers may want Linx radio frequency (“RF”)
!
products to control machinery or devices remotely, including machinery
or devices that can cause death, bodily injuries, and/or property
damage if improperly or inadvertently triggered, particularly in industrial
settings or other applications implicating life-safety concerns (“Life and
Property Safety Situations”).
Table of Contents
1 Description
1 Features
1 Applications Include
NO OEM LINX REMOTE CONTROL OR FUNCTION MODULE
SHOULD EVER BE USED IN LIFE AND PROPERTY SAFETY
SITUATIONS. No OEM Linx Remote Control or Function Module
should be modified for Life and Property Safety Situations. Such
modification cannot provide sufficient safety and will void the product’s
regulatory certification and warranty.
Customers may use our (non-Function) Modules, Antenna and
Connectors as part of other systems in Life Safety Situations, but
only with necessary and industry appropriate redundancies and
in compliance with applicable safety standards, including without
limitation, ANSI and NFPA standards. It is solely the responsibility
of any Linx customer who uses one or more of these products to
incorporate appropriate redundancies and safety standards for the Life
and Property Safety Situation application.
Do not use this or any Linx product to trigger an action directly
from the data line or RSSI lines without a protocol or encoder/
decoder to validate the data. Without validation, any signal from
another unrelated transmitter in the environment received by the module
could inadvertently trigger the action.
All RF products are susceptible to RF interference that can prevent
communication. RF products without frequency agility or hopping
implemented are more subject to interference. This module does not
have a frequency hopping protocol built in.
Do not use any Linx product over the limits in this data guide.
Excessive voltage or extended operation at the maximum voltage could
cause product failure. Exceeding the reflow temperature profile could
cause product failure which is not immediately evident.
Do not make any physical or electrical modifications to any Linx
product. This will void the warranty and regulatory and UL certifications
and may cause product failure which is not immediately evident.
2 Ordering Information
2 Absolute Maximum Ratings
2 ElectricalSpecications
4 Pin Assignments
4 Pin Descriptions
5 A Brief Overview of GPS
6 Time To First Fix (TTFF)
6 Module Description
7 Backup Battery
7 Power Supply Requirements
7 The 1PPS Output
7 Hybrid Ephemeris Prediction (AGPS)
8 Antenna Considerations
9 Power Control
10 Slow Start Time
11 Interfacing with NMEA Messages
12 NMEA Output Messages
18 Input Messages
32 Typical Applications
33 Microstrip Details
34 Board Layout Guidelines
35 Pad Layout
36 Production Guidelines
36 Hand Assembly
36 Automated Assembly
38 Master Development System
Page 3
39 Resources
40 Appendix A
FM Series GPS Receiver
Data Guide
Description
The FM Series GPS receiver module is a
self-contained high-performance Global
Positioning System receiver. Based on
the MediaTek MT3339 chipset, it can
simultaneously acquire on 66 channels and
track on up to 22 channels. This gives the
module fast lock times and high position
accuracy even at low signal levels.
The module’s exceptional sensitivity gives it
superior performance, even in dense foliage and urban canyons. Its very
low power consumption helps maximize runtimes in battery powered
applications. The module outputs standard NMEA data messages through
a UART interface.
Housed in a compact reflow-compatible SMD package, the receiver
requires no programming or additional RF components (except an antenna)
to form a complete GPS solution. This makes the FM Series easy to
integrate, even by engineers without previous RF or GPS experience.
0.512 in
(13.00 mm)
0.087 in
(2.20 mm)
Figure 1: Package Dimensions
0.591 in
(15.00 mm)
RXM-GPS-FM
LOT GRxxxx
Warning: This product incorporates numerous static-sensitive
components. Always wear an ESD wrist strap and observe proper ESD
handling procedures when working with this device. Failure to observe
this precaution may result in module damage or failure.
Features
• MediaTek chipset
• High sensitivity (–161dBm)
• Fast TTFF at low signal levels
• ±11ns 1PPS accuracy
• Battery-backed SRAM
• 3-day ephemeris prediction
• No programming necessary
Applications Include
• Positioning and Navigation
• Location and Tracking
• Security/Loss-Prevention
• No external RF components
needed (except an antenna)
• No production tuning
• UART serial interface
• Power control features
• Compact SMD package
• Surveying
• Logistics
• Fleet Management
– –
1
Revised 3/18/2015
Page 4
Ordering Information
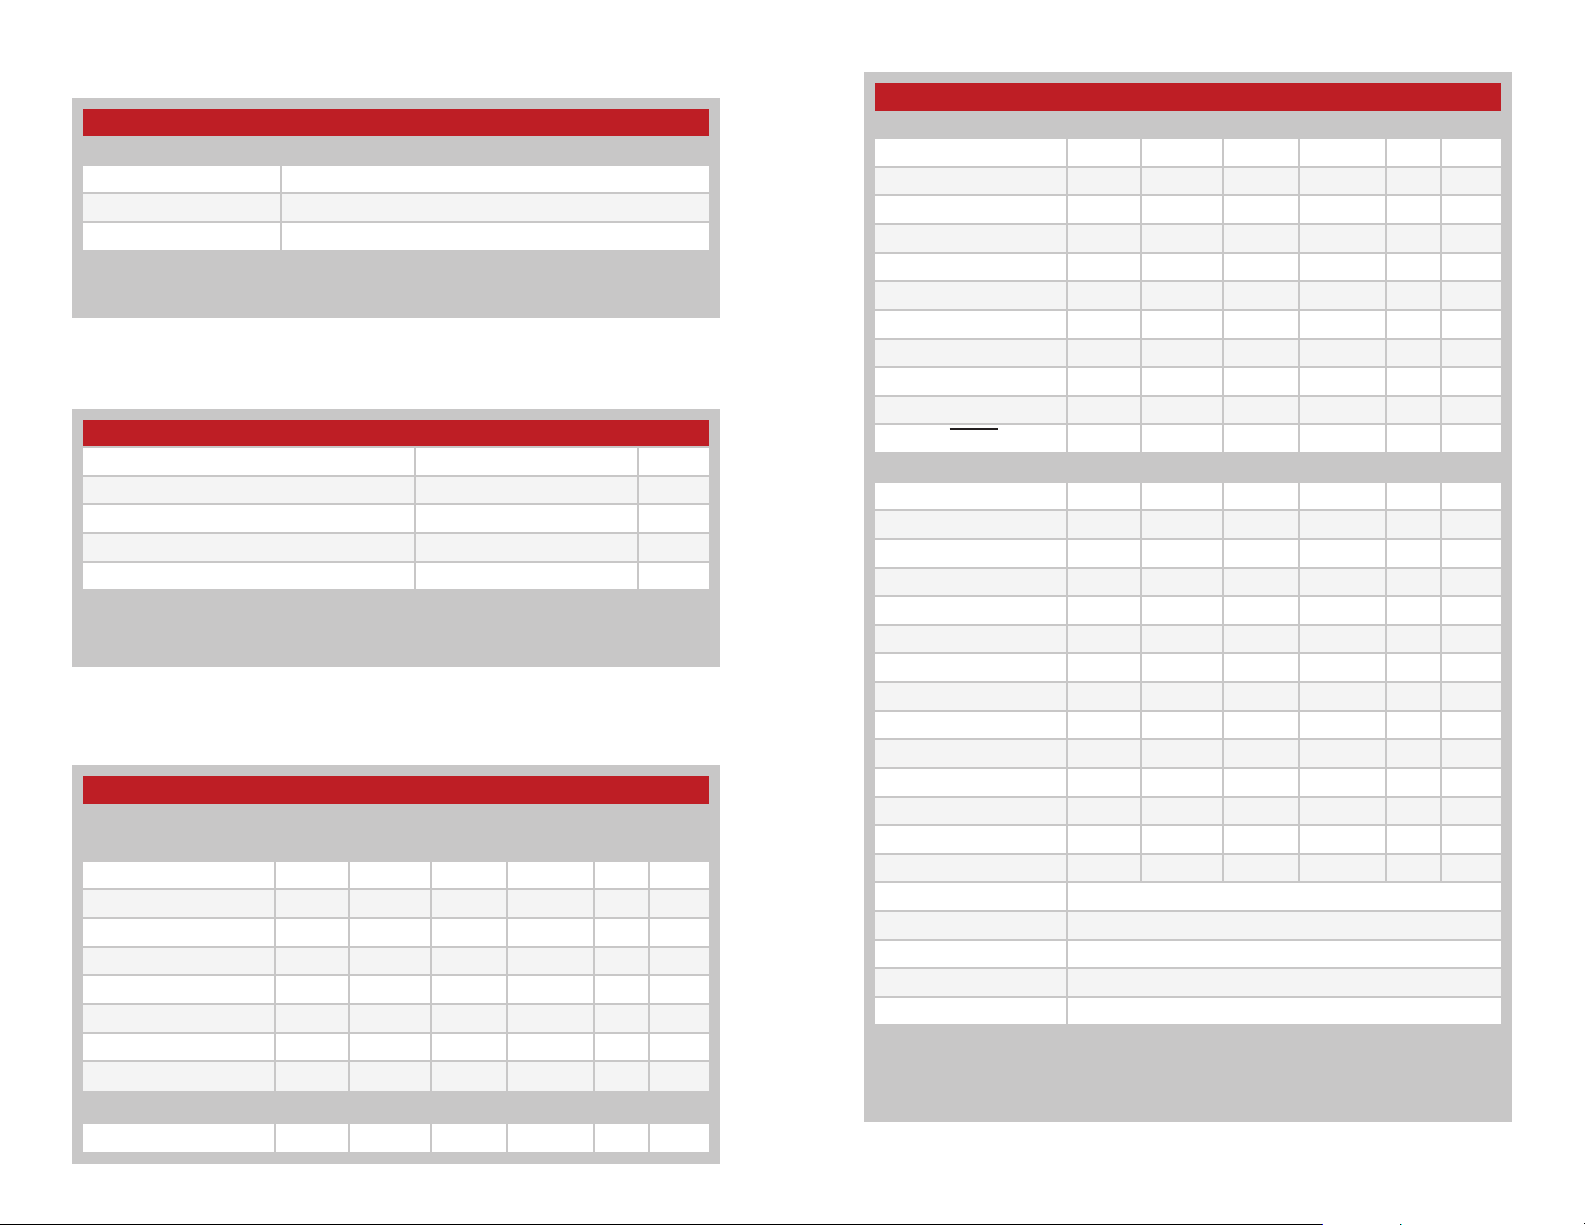
Ordering Information
Part Number Description
RXM-GPS-FM-x FM Series GPS Receiver Module
MDEV-GPS-FM FM Series GPS Receiver Master Development System
EVM-GPS-FM FM Series Evaluation Module
x = “T” for Tape and Reel, “B” for Bulk
Reels are 1,000 pieces. Quantities less than 1,000 pieces are supplied in bulk
Figure 2: Ordering Information
Absolute Maximum Ratings
Absolute Maximum Ratings
Supply Voltage V
CC
+4.3 VDC
Input Battery Backup Voltage +4.3 VDC
VOUT Output Current 50 mA
Operating Temperature −40 to +85 ºC
Storage Temperature −40 to +85 ºC
Exceeding any of the limits of this section may lead to permanent damage to the device.
Furthermore, extended operation at these maximum ratings may reduce the life of this
device.
Figure 3: Absolute Maximum Ratings
ElectricalSpecications
FM Series GNSS Receiver Specifications
Parameter Symbol Min. Typ. Max. Units Notes
Power Supply
Operating Voltage V
Supply Current l
CC
CC
Peak 66 mA 1
Acquisition 14 mA 1
Tracking 12 mA 1, 2
Standby 0.150 mA 1
Backup Battery Voltage V
Backup Battery Current I
BAT
BAT
Antenna Port
RF Impedance R
IN
3.0 3.3 4.3 VDC
2.0 4.3 VDC
7 µA 2
50 Ω
FM Series GNSS Receiver Specifications
Parameter Symbol Min. Typ. Max. Units Notes
VOUT Output Voltage V
VOUT Output Current I
Output Low Voltage V
Output High Voltage V
Output Low Current I
Output High Current I
Input Low Voltage V
Input High Voltage V
Input Low Current I
Input High Current I
Minimum RESET Pulse T
OUT
OUT
OL
OH
OL
OH
IL
IH
IL
IH
RST
2.7 2.8 2.9 VDC
30 mA 3
0.4 VDC
2.4
2.0 mA
2.0 mA
−0.3 0.8 VDC
2.0 3.6 VDC
−1 1 µA 4
−1 1 µA 4
1 ms
Receiver Section
Receiver Sensitivity
Tracking −161 dBm
Cold Start −143 dBm
Acquisition Time
Hot Start (Open Sky) 1 s
Hot Start (Indoor) 30 s
Cold Start 32 s
Cold Start, AGPS 15 s
Position Accuracy
Autonomous 3 m
SBAS 2.5 m
1PPS Accuracy −11 11 ns
Altitude 50,000 m
Velocity 515 m/s
Chipset MediaTek MT3339
Frequency L1 1575.42MHz, C/A code
Channels 22 tracking, 66 acquisition
Update Rate 1Hz default, up to 10Hz
Protocol Support NMEA 0183 ver 3.01
1. VCC = 3.3V, without active antenna, ephemeris prediction is off,
2. Position fix is available
IOUT
= 0
3. VCC = 0V
4. No pull-up or pull-down on the lines
Figure 4: Electrical Specifications
– –
2 3
– –
Page 5
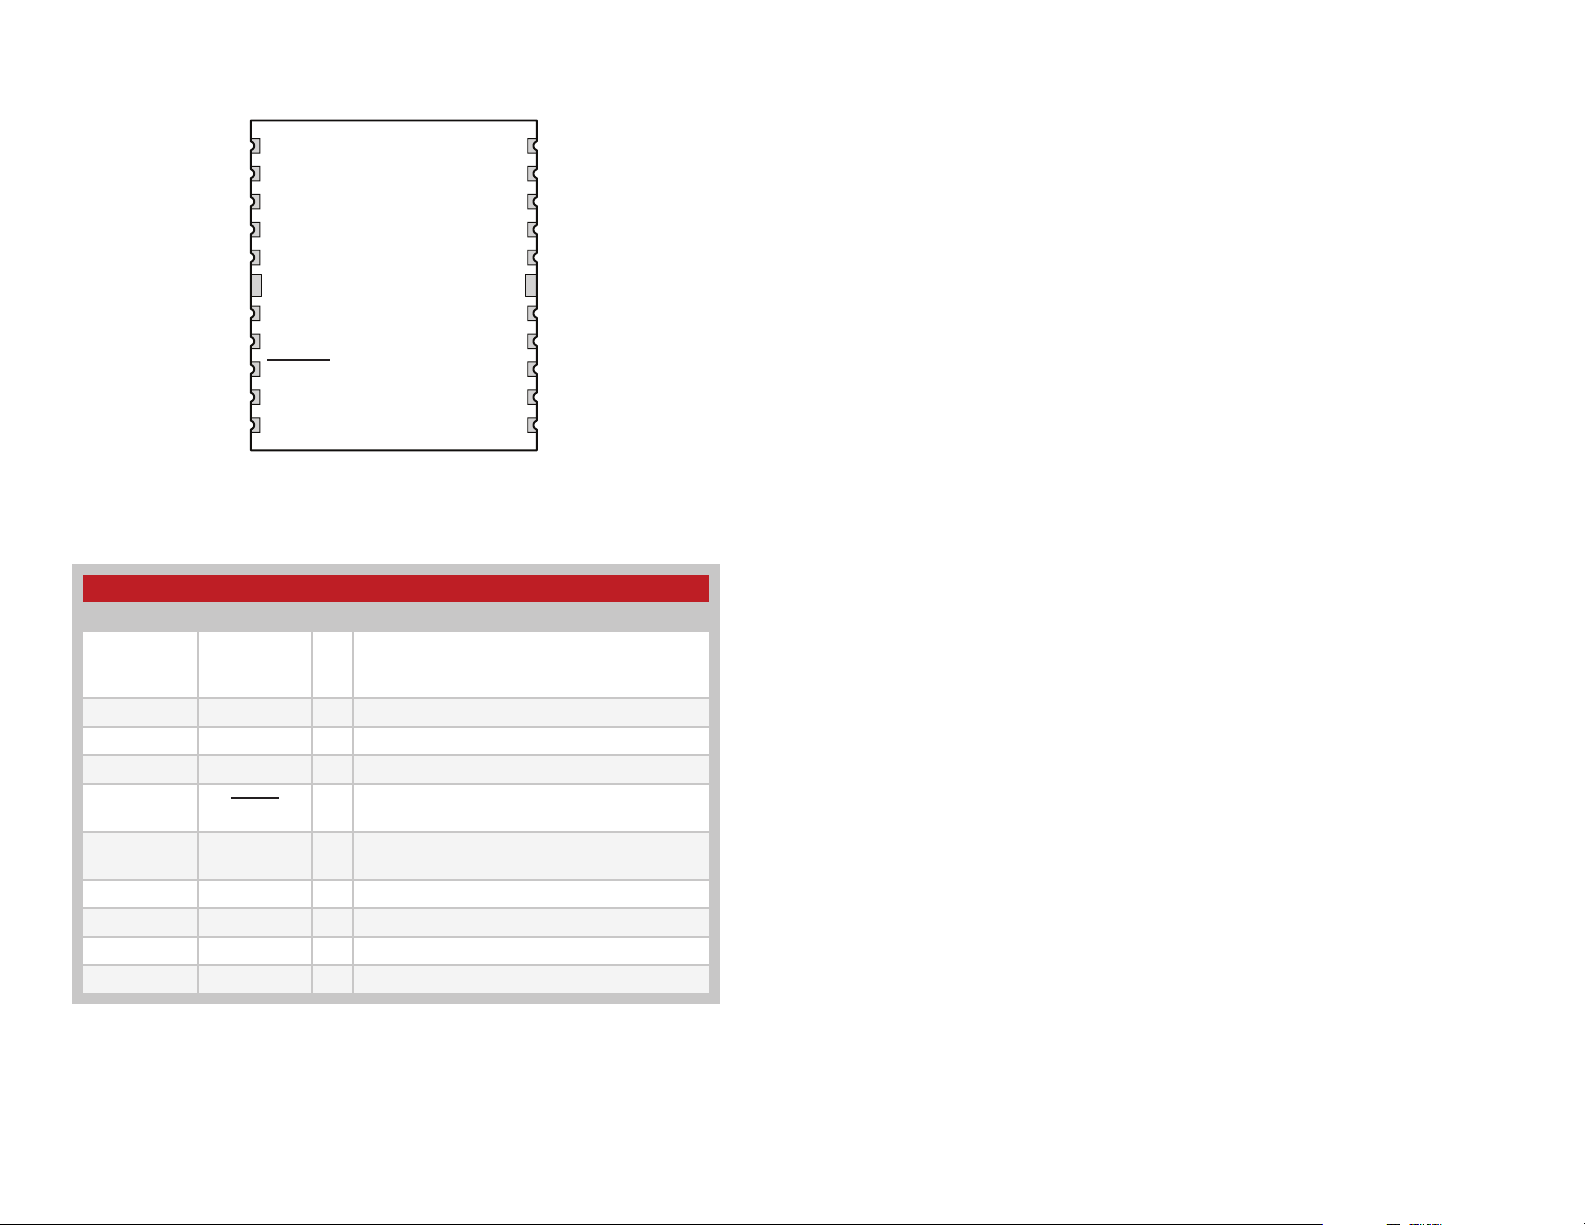
Pin Assignments
A Brief Overview of GPS
The Global Positioning System (GPS) is a U.S.-owned utility that freely and
NC1
NC2
1PPS3
TX4
RX5
GND21
NC6
NC7
RESET8
NC9
NC10
GND 20
RFIN 19
GND 18
VOUT 17
NC 16
GND 22
NC 15
NC 14
NC 13
VCC 12
VBACKUP 11
continuously provides positioning, navigation, and timing (PNT) information.
Originally created by the U.S. Department of Defense for military
applications, the system was made available without charge to civilians
in the early 1980s. The global positioning system consists of a nominal
constellation of 24 satellites orbiting the earth at about 12,000 nautical
miles in height. The pattern and spacing of the satellites allow at least four
to be visible above the horizon from any point on the Earth. Each satellite
transmits low power radio signals which contain three different bits of
information; a pseudorandom code identifying the satellite, ephemeris data
which contains the current date and time as well as the satellite’s health,
and the almanac data which tells where each satellite should be at any time
throughout the day.
Figure 5: FM Series GPS Receiver Pinout (Top View)
Pin Descriptions
Pin Descriptions
Pin Number Name I/O Description
1, 2, 6, 7, 9,
10, 13, 14,
15, 16
3 1PPS O 1 Pulse Per Second (11nS accuracy)
4 TX O Serial output (default NMEA)
5 RX I Serial input (default NMEA)
8 RESET I
11 VBACKUP P
12 VCC P Supply Voltage
17 VOUT O 2.8V output for an active antenna
18, 20, 21, 22 GND P Ground
19 RFIN I GPS RF signal input
Figure 6: FM Series GPS Receiver Pin Descriptions
NC − No electrical connection
Active low module reset. This line is pulled high
internally. Leave it unconnected if it is not used.
Backup battery supply voltage. This line must be
powered to enable the module.
A GPS receiver receives and times the signals sent by multiple satellites
and calculates the distance to each satellite. If the position of each satellite
is known, the receiver can use triangulation to determine its position
anywhere on the earth. The receiver uses four satellites to solve for four
unknowns; latitude, longitude, altitude and time. If any of these factors is
already known to the system, an accurate position (fix) can be obtained
with fewer satellites in view. Tracking more satellites improves calculation
accuracy. In essence, the GPS system provides a unique address for every
square meter on the planet.
A faster Time To First Fix (TTFF) is also possible if the satellite information
is already stored in the receiver. If the receiver knows some of this
information, then it can accurately predict its position before acquiring an
updated position fix. For example, aircraft or marine navigation equipment
may have other means of determining altitude, so the GPS receiver would
only have to lock on to three satellites and calculate three equations to
provide the first position fix after power-up.
– –
4 5
– –
Page 6
Time To First Fix (TTFF)
TTFF is often broken down into three parts:
Cold: A cold start is when the receiver has no accurate knowledge of its
position or time. This happens when the receiver’s internal Real Time Clock
(RTC) has not been running or it has no valid ephemeris or almanac data.
In a cold start, the receiver takes up to 30 seconds to acquire its position.
Warm: A typical warm start is when the receiver has valid almanac and time
data and has not significantly moved since its last valid position calculation.
This happens when the receiver has been shut down for more than 2
hours, but still has its last position, time, and almanac saved in memory,
and its RTC has been running. The receiver can predict the location of the
current visible satellites and its location; however, it needs to wait for an
ephemeris broadcast (every 30 seconds) before it can accurately calculate
its position.
Hot: A hot start is when the receiver has valid ephemeris, time, and
almanac data. In a hot start, the receiver takes 1 second to acquire its
position. The time to calculate a fix in this state is sometimes referred to as
Time to Subsequent Fix or TTSF.
Backup Battery
The module is designed to work with a backup battery that keeps the
SRAM memory and the RTC powered when the RF section and the main
GPS core are powered down. This enables the module to have a faster
Time To First Fix (TTFF) when it is powered back on. The memory and
clock pull about 6µA. This means that a small lithium battery is sufficient to
power these sections. This significantly reduces the power consumption
and extends the main battery life while allowing for fast position fixes when
the module is powered back on.
The backup battery must be installed for the module to be enabled.
Power Supply Requirements
The module requires a clean, well-regulated power source. While it is
preferable to power the unit from a battery, it can operate from a power
supply as long as noise is less than 20mV. Power supply noise can
significantly affect the receiver’s sensitivity, therefore providing clean power
to the module should be a high priority during design. Bypass capacitors
should be placed as close as possible to the module. The values should be
adjusted depending on the amount and type of noise present on the supply
line.
Module Description
The FM Series GPS Receiver module is based on the MediaTek MT3339
chipset, which consumes less power than competitive products while
providing exceptional performance even in dense foliage and urban
canyons. No external RF components are needed other than an antenna.
The simple serial interface and industry standard NMEA protocol make
integration of the FM Series into an end product extremely straightforward.
The module’s high-performance RF architecture allows it to receive GPS
signals that are as low as –161dBm. The FM Series can track up to 22
satellites at the same time. Once locked onto the visible satellites, the
receiver calculates the range to the satellites and determines its position
and the precise time. It then outputs the data through a standard serial port
using several standard NMEA protocol formats.
The GPS core handles all of the necessary initialization, tracking, and
calculations autonomously, so no programming is required. The RF section
is optimized for low level signals, and requires no production tuning.
– –
6 7
The 1PPS Output
The 1PPS line outputs 1 pulse per second on the rising edge of the GPS
second when the receiver has an over-solved navigation solution from five
or more satellites. The pulse has a duration of 100ms with the rising edge
on the GPS second. This line is low until the receiver acquires a 3D fix.
The GPS second is based on the atomic clocks in the satellites, which are
monitored and set to Universal Time master clocks. This output and the
time calculated from the satellite transmissions can be used as a clock
feature in an end product with ±11ns accuracy.
Hybrid Ephemeris Prediction (AGPS)
AGPS is where the receiver uses the ephemeris data broadcast by the
satellites to calculate models of each visible satellite’s future location. This
allows the receiver to store up to 3 days’ worth of ephemeris data and
results in faster TTFF. Having this data reduces the cold start time to less
than 15 seconds. Contact Linx for details on this.
– –
Page 7
Antenna Considerations
Standby
Cold Start
The FM Series module is designed to utilize a wide variety of external
antennas. The module has a regulated power output which simplifies
the use of GPS antenna styles which require external power. This allows
the designer great flexibility, but care must be taken in antenna selection
to ensure optimum performance. For example, a handheld device may
be used in many varying orientations so an antenna element with a wide
and uniform pattern may yield better overall performance than an antenna
element with high gain and a correspondingly narrower beam. Conversely,
an antenna mounted in a fixed and predictable manner may benefit from
pattern and gain characteristics suited to that application. Evaluating
multiple antenna solutions in real-world situations is a good way to rapidly
assess which will best meet the needs of your application.
For GPS, the antenna should have good right hand circular polarization
characteristics (RHCP) to match the polarization of the GPS signals.
Ceramic patches are the most commonly used style of antenna, but
there are many different shapes, sizes and styles of antennas available.
Regardless of the construction, they will generally be either passive or
active types. Passive antennas are simply an antenna tuned to the correct
frequency. Active antennas add a Low Noise Amplifier (LNA) after the
antenna and before the module to amplify the weak GPS satellite signals.
For active antennas, a 300 ohm ferrite bead can be used to connect the
VOUT line to the RFIN line. This bead prevents the RF from getting into the
power supply, but allows the DC voltage onto the RF trace to feed into the
antenna. A series capacitor inside the module prevents this DC voltage
from affecting the bias on the module’s internal LNA.
Maintaining a 50 ohm path between the module and antenna is critical.
Errors in layout can significantly impact the module’s performance. Please
review the layout guidelines section carefully to become more familiar with
these considerations.
Power Control
The FM Series GPS Receiver module offers several ways to control the
module’s power. A serial command puts the module into a low-power
standby mode that consumes only 150µA of current. An external processor
can be used to power the module on and off to conserve battery power.
In addition, the module includes a duty cycle mode where the module will
power on for a configurable amount of time to obtain a position fix then
power off for a configurable amount of time. In this way the module can
handle all of the timing without any intervention from the external processor.
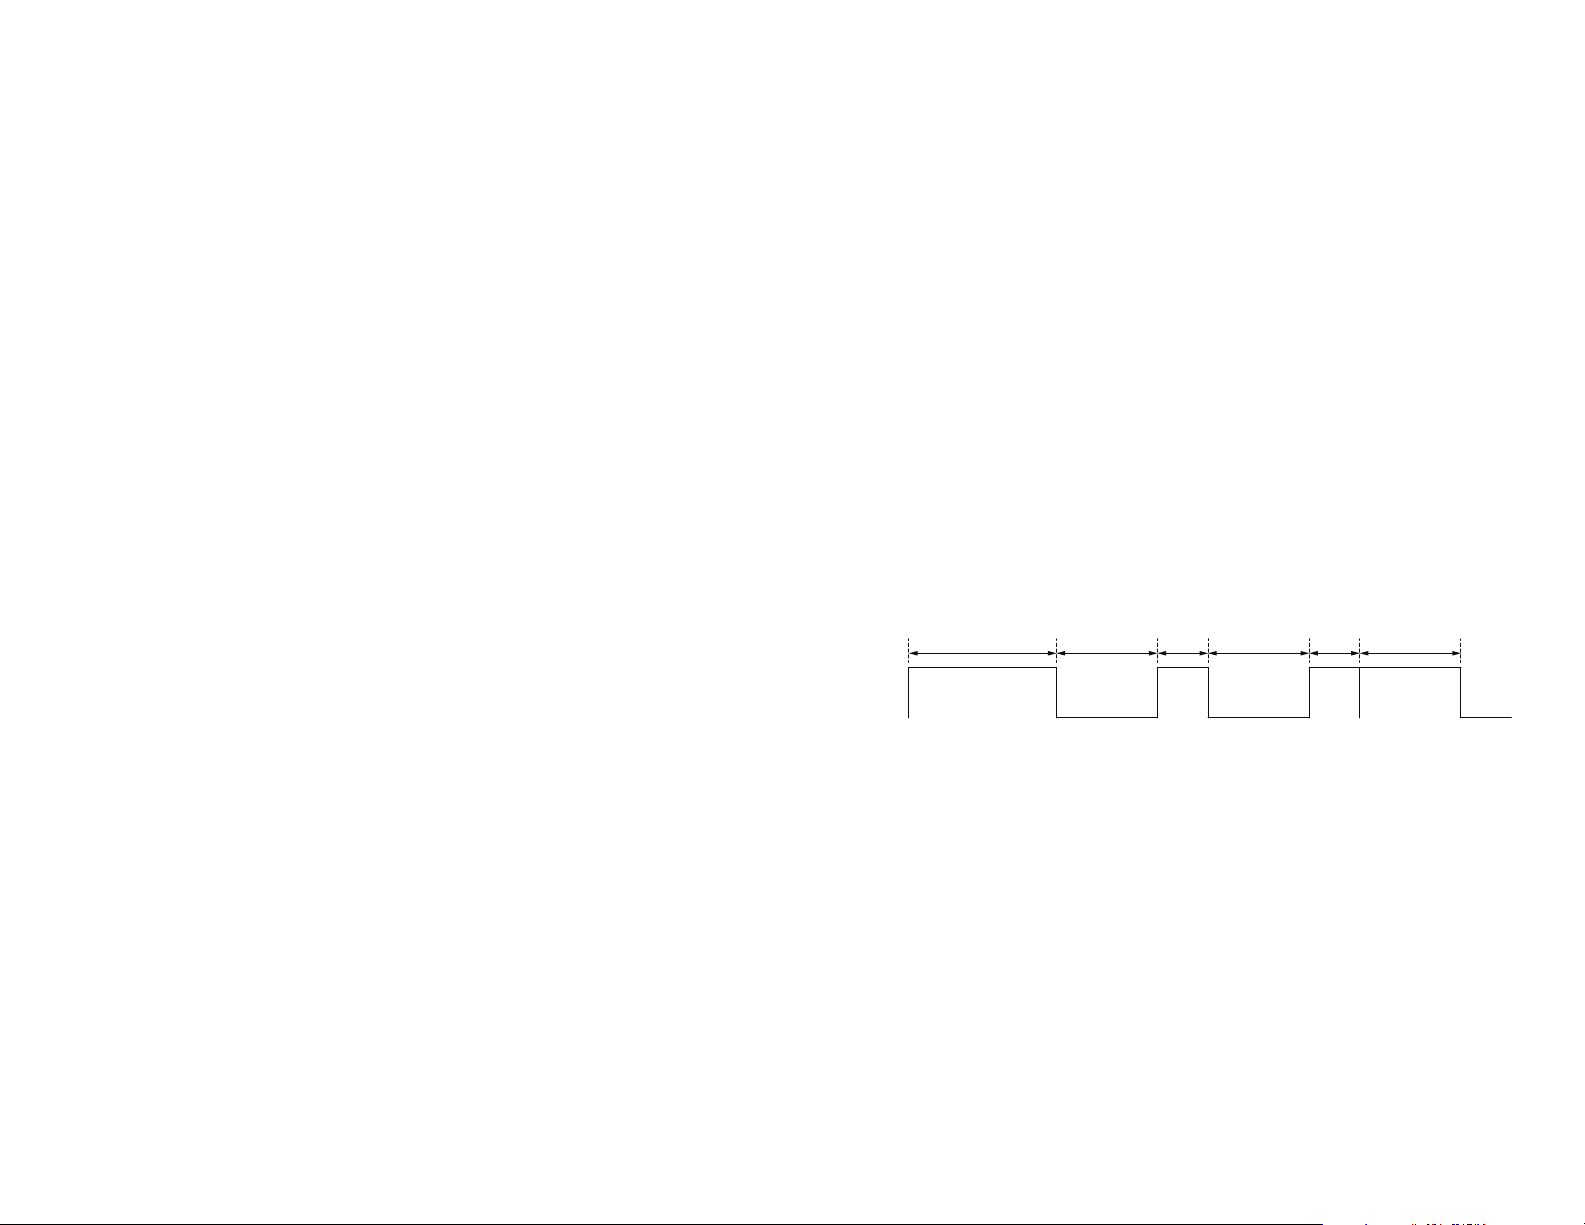
There are four times that are configured with duty cycle mode. The on
time and standby times are the amount of times that the module is on and
in standby in normal operation. There are also cold start on and standby
times. These are used to keep the module on longer in the event of a cold
start so that it can gather the required satellite data for a position fix. After
this, the module uses the normal operation times.
In the event that the module’s stored ephemeris data becomes invalid the
module supports and extended receive time to gather the required data
from the satellites. Figure 7 shows the power control times.
Cold Start On Time
ON
Figure 7: FM Series GPS Receiver Power Control
The module supports MediaTek’s proprietary AlwaysLocateTM mode. In
this mode, the module automatically adapts the on and standby times to
the current environmental conditions to balance position accuracy and
power consumption. In this mode, any byte sent to the module triggers it to
output the current position data.
Standby mode is configured by command 161. Extended receive time is
configured by command 223. Command 225 configures which duty cycle
mode is used.
Standby Time Standby TimeOn Time On Time Extended RX Time
– –
8 9
– –
Page 8
Slow Start Time
The most critical factors in start time are current ephemeris data, signal
strength and sky view. The ephemeris data describes the path of each
satellite as they orbit the earth. This is used to calculate the position of
a satellite at a particular time. This data is only usable for a short period
of time, so if it has been more than a few hours since the last fix or if the
location has significantly changed (a few hundred miles), then the receiver
may need to wait for a new ephemeris transmission before a position can
be calculated. The GPS satellites transmit the ephemeris data every 30
seconds. Transmissions with a low signal strength may not be received
correctly or be corrupted by ambient noise. The view of the sky is important
because the more satellites the receiver can see, the faster the fix and the
more accurate the position will be when the fix is obtained.
If the receiver is in a very poor location, such as inside a building, urban
canyon, or dense foliage, then the time to first fix can be slowed. In very
poor locations with poor signal strength and a limited view of the sky with
outdated ephemeris data, this could be on the order of several minutes.
In the worst cases, the receiver may need to receive almanac data, which
describes the health and course data for every satellite in the constellation.
This data is transmitted every 15 minutes. If a lock is taking a long time, try
to find a location with a better view of the sky and fewer obstructions. Once
locked, it is easier for the receiver to maintain the position fix.
Interfacing with NMEA Messages
Linx modules default to the NMEA protocol. Output messages are sent
from the receiver on the TX line and input messages are sent to the receiver
on the RX line. By default, output messages are sent once every second.
Details of each message are described in the following sections.
The NMEA message format is as follows: <Message-ID + Data Payload +
Checksum + End Sequence>. The serial data structure defaults to
9,600bps, 8 data bits, 1 start bit, 1 stop bit, and no parity. Each message
starts with a $ character and ends with a <CR> <LF>. All fields within
each message are separated by a comma. The checksum follows the *
character and is the last two characters, not including the <CR> <LF>.
It consists of two hex digits representing the exclusive OR (XOR) of all
characters between, but not including, the $ and * characters. When
reading NMEA output messages, if a field has no value assigned to it, the
comma will still be placed following the previous comma. For example,
{,04,,,,,2.0,} shows four empty fields between values 04 and 2.0. When
writing NMEA input messages, all fields are required, none are optional. An
empty field will invalidate the message and it will be ignored.
Reading NMEA output messages:
• Initialize a serial interface to match the serial data structure of the GPS
receiver.
• Read the NMEA data from the TX pin into a receive buffer.
• Separate it into six buffers, one for each message type. Use the
characters ($) and <CR> <LF> as end points for each message.
• For each message, calculate the checksum as mentioned above to
compare with the received checksum.
• Parse the data from each message using commas as field separators.
• Update the application with the parsed field values.
• Clear the receive buffer and be ready for the next set of messages.
Writing NMEA input messages:
• Initialize a serial interface to match the serial data structure of the
receiver.
• Assemble the message to be sent with the calculated checksum.
• Transmit the message to the receiver on the RX line.
– –
10 11
– –
Page 9
NMEA Output Messages
The following sections outline the data structures of the various NMEA
messages that are supported by the module. By default, the NMEA
commands are output at 9,600bps, 8 data bits, 1 start bit, stop bit, and no
parity.
Six messages are output at a 1Hz rate by default. These messages are
shown in Figure 8.
NMEA Output Messages
Name Description
GGA Contains the essential fix data which provide location and accuracy
GLL Contains just position and time
GSA Contains data on the Dilution of Precision (DOP) and which satellites are used
GSV
RMC Contains the minimum data of time, position, speed and course
Figure 8: NMEA Output Messages
Details of each message and examples are given in the following sections.
Contains the satellite location relative to the receiver and its signal to noise
ratio. Each message can describe 4 satellites so multiple messages may be
output depending on the number of satellites being tracked.
VTG Contains the course and speed over the ground
GGA – Global Positioning System Fix Data
Figure 9 contains the values for the following example:
$GPGGA,053740.000,2503.6319,N,12136.0099,E,1,08,1.1,63.8,M,15.2,M,,0000*64
Global Positioning System Fix Data Example
Name Example Units Description
Message ID $GPGGA GGA protocol header
UTC Time 053740.000 hhmmss.sss
Latitude 2503.6319 ddmm.mmmm
N/S Indicator N N=north or S=south
Longitude 12136.0099 dddmm.mmmm
E/W Indicator E E=east or W=west
Position Fix Indicator 1 See Figure 10
Satellites Used 08 Range 0 to 33
HDOP 1.1 Horizontal Dilution of Precision
MSL Altitude 63.8 meters
Units M meters
Geoid Separation 15.2 meters
Units M meters
Age of Diff. Corr. second Null fields when DGPS is not used
Diff. Ref. Station 0000
Checksum *64
<CR> <LF> End of message termination
Figure 9: Global Positioning System Fix Data Example
Position Indicator Values
Value Description
0 Fix not available or invalid
1 GPS SPS Mode, fix valid
2 Differential GPS, SPS Mode, fix valid
3–5 Not supported
6 Dead Reckoning Mode, fix valid (requires external hardware)
Figure 10: Position Indicator Values
– –
12 13
– –
Page 10
GLL – Geographic Position – Latitude / Longitude
Figure 11 contains the values for the following example:
$GPGLL,2503.6319,N,12136.0099,E,053740.000,A,A*52
Geographic Position – Latitude / Longitude Example
Name Example Units Description
Message ID $GPGLL GLL protocol header
Latitude 2503.6319 ddmm.mmmm
N/S Indicator N N=north or S=south
Longitude 12136.0099 dddmm.mmmm
E/W Indicator E E=east or W=west
UTC Time 053740.000 hhmmss.sss
Status A A=data valid or V=data not valid
Mode A
Checksum *52
<CR> <LF> End of message termination
Figure 11: Geographic Position – Latitude / Longitude Example
A=autonomous, D=DGPS, N=Data not
valid, R=Coarse Position, S=Simulator
GSA – GPS DOP and Active Satellites
Figure 12 contains the values for the following example:
$GPGSA,A,3,24,07,17,11,28,08,20,04,,,,,2.0,1.1,1.7*35
GPS DOP and Active Satellites Example
Name Example Units Description
Message ID $GPGSA GSA protocol header
Mode 1 A See Figure 13
Mode 2 3 1=No fix, 2=2D, 3=3D
ID of satellite used 24 Sv on Channel 1
ID of satellite used 07 Sv on Channel 2
... ...
ID of satellite used Sv on Channel N
PDOP 2.0 Position Dilution of Precision
HDOP 1.1 Horizontal Dilution of Precision
VDOP 1.7 Vertical Dilution of Precision
Checksum *35
<CR> <LF> End of message termination
Mode 1 Values
Value Description
M Manual – forced to operate in 2D or 3D mode
A Automatic – allowed to automatically switch 2D/3D
Figure 13: Mode 1 Values
GSV – GPS Satellites in View
Figure 14 contains the values for the following example:
$GPGSV,3,1,12,28,81,285,42,24,67,302,46,31,54,354,,20,51,077,46*73
$GPGSV,3,2,12,17,41,328,45,07,32,315,45,04,31,250,40,11,25,046,41*75
$GPGSV,3,3,12,08,22,214,38,27,08,190,16,19,05,092,33,23,04,127,*7B
GPS Satellites in View Example
Name Example Units Description
Message ID $GPGSV GSV protocol header
Total number of
messages
Message number
Satellites in view 12
Satellite ID 28 Channel 1 (Range 01 to 196)
Elevation 81 degrees Channel 1 (Range 00 to 90)
Azimuth 285 degrees Channel 1 (Range 000 to 359)
SNR (C/No) 42 dB–Hz
Satellite ID 20 Channel 2 (Range 01 to 196)
Elevation 51 degrees Channel 2 (Range 00 to 90)
Azimuth 077 degrees Channel 2 (Range 000 to 359)
SNR (C/No) 46 dB-Hz
Checksum *73
<CR> <LF> End of message termination
1. Depending on the number of satellites tracked, multiple messages of GSV data
may be required.
Figure 14: GPS Satellites in View Example
1
3 Range 1 to 4
1
1 Range 1 to 4
Channel 1 (Range 00 to 99, null when not
tracking)
Channel 2 (Range 00 to 99, null when not
tracking.
Figure 12: GPS DOP and Active Satellites Example
– –
14 15
– –
Page 11
RMC – Recommended Minimum Specific GNSS Data
Figure 15 contains the values for the following example:
$GPRMC,053740.000,A,2503.6319,N,12136.0099,E,2.69,79.65,100106,,,A*53
VTG – Course Over Ground and Ground Speed
Figure 16 contains the values for the following example:
$GPVTG,79.65,T,,M,2.69,N,5.0,K,A*38
Recommended Minimum Specific GNSS Data Example
Name Example Units Description
Message ID $GPRMC RMC protocol header
UTC Time 053740.000 hhmmss.sss
Status A A=data valid or V=data not valid
Latitude 2503.6319 ddmm.mmmm
N/S Indicator N N=north or S=south
Longitude 12136.0099 dddmm.mmmm
E/W Indicator E E=east or W=west
Speed over ground 2.69 knots TRUE
Course over ground 79.65 degrees
Date 100106 ddmmyy
Magnetic Variation degrees Not available, null field
Variation Sense E=east or W=west (not shown)
Mode A
Checksum *53
<CR> <LF> End of message termination
Figure 15: Recommended Minimum Specific GNSS Data Example
A=autonomous, D=DGPS, E=DR, N=
Data not valid, R=Coarse Position,
S=Simulator
Course Over Ground and Ground Speed Example
Name Example Units Description
Message ID $GPVTG VTG protocol header
Course over ground 79.65 degrees Measured heading
Reference T TRUE
Course over ground degrees Measured heading (N/A, null field)
Reference M Magnetic
Speed over ground 2.69 knots Measured speed
Units N Knots
Speed over ground 5.0 km/hr Measured speed
Units K Kilometer per hour
Mode A
Checksum *38
<CR> <LF> End of message termination
Figure 16: Course Over Ground and Ground Speed Example
A=autonomous, D=DGPS, N=
Data not valid, R=Coarse Position,
S=Simulator
Start-up Response
The module outputs a message when it starts up to indicate its state. The
normal start-up message is shown below and the message formatting is
shown in Figure 17.
$PMTK010,001*2E<CR><LF>
Start-up Response Example
Name Example Description
Message ID $PMTK010 Message header
System Message
Message MSG
Checksum CKSUM
End Sequence <CR> <LF> End of message termination
Figure 17: Start-up Response Example
– –
16 17
0 = Unknown
1 = Start-up
2 = Notification for the host supporting EPO
3 = Transition to Normal operation is successful
– –
Page 12
Input Messages
The following outlines the serial commands input into the module for
configuration. There are 3 types of input messages: commands, writes and
reads. The module outputs a response for each input message.
The commands are used to change the operating state of the module.
The writes are used to change the module’s configuration and the reads
are used to read out the current configuration. Messages are formatted as
shown in Figure 18. All fields in each message are separated by a comma.
Serial Data Structure
Name Example Description
Start Sequence $PMTK
Message ID <MID>
Payload DATA Message specific data.
Checksum CKSUM
End Sequence <CR> <LF>
Figure 18: Serial Data Structure
Figure 19 shows the input commands.
Input Commands
Name Description
101 Hot Re-start
102 Warm Re-start
103 Cold Re-start
104 Restore Default Configuration
161 Standby Mode
220 Position Fix Interval
223 Ephemeris Data Receive Time
225 Receiver Duty Cycle
251 Baud Rate
Message Identifier consisting of three numeric
characters.
CKSUM is a two-hex character checksum as
defined in the NMEA specification, NMEA-0183
Standard for Interfacing Marine Electronic Devices.
Checksums are required on all input messages.
Each message must be terminated using Carriage
Return (CR) Line Feed (LF) (\r\n, 0x0D0A) to cause
the receiver to process the input message. They
are not printable ASCII characters, so are omitted
from the examples.
The write and read messages are shown in Figure 20. A write message
triggers an acknowledgement from the module. A read message triggers a
response message containing the requested information.
Input Write and Read Messages
Description Write ID Read ID Response ID
Position Fix Interval 300 400 500
DGPS Source 301 401 501
SBAS Enable 313 413 513
NMEA Output Messages 314 414 514
Set Datum 330 430 530
Static Navigation Threshold 386 447 527
Enable Ephemeris Prediction 869 869 869
Figure 20: Input Write and Read Messages
The module responds to commands with response messages. The
acknowledge message is formatted as shown in Figure 21.
Acknowledge Message
Name Example Description
Start Sequence $PMTK
Message ID 001 Acknowledge Identifier
Command CMD The command that triggered the acknowledge
Flag indicating the outcome of the command
Flag Flg
Checksum CKSUM
End Sequence <CR> <LF>
Figure 21: Acknowledge Message
0 = Invalid Command
1 = Unsupported Command
2 = Valid command, but action failed
3 = Valid command and action succeeded
CKSUM is a two-hex character checksum as
defined in the NMEA specification, NMEA-0183
Standard for Interfacing Marine Electronic Devices.
Checksums are required on all input messages.
Each message must be terminated using Carriage
Return (CR) Line Feed (LF) (\r\n, 0x0D0A) to cause
the receiver to process the input message. They
are not printable ASCII characters, so are omitted
from the examples.
Figure 19: Input Commands
– –
18 19
– –
Page 13
101 – Hot Re-start
This command instructs the module to conduct a hot re-start using all of
the data stored in memory. Periodic mode and static navigation settings are
returned to default when this command is executed.
$PMTK101*32<CR><LF>
102 – Warm Re-start
This command instructs the module to conduct a warm re-start that does
not use the saved ephemeris data. Periodic mode and static navigation
settings are returned to default when this command is executed.
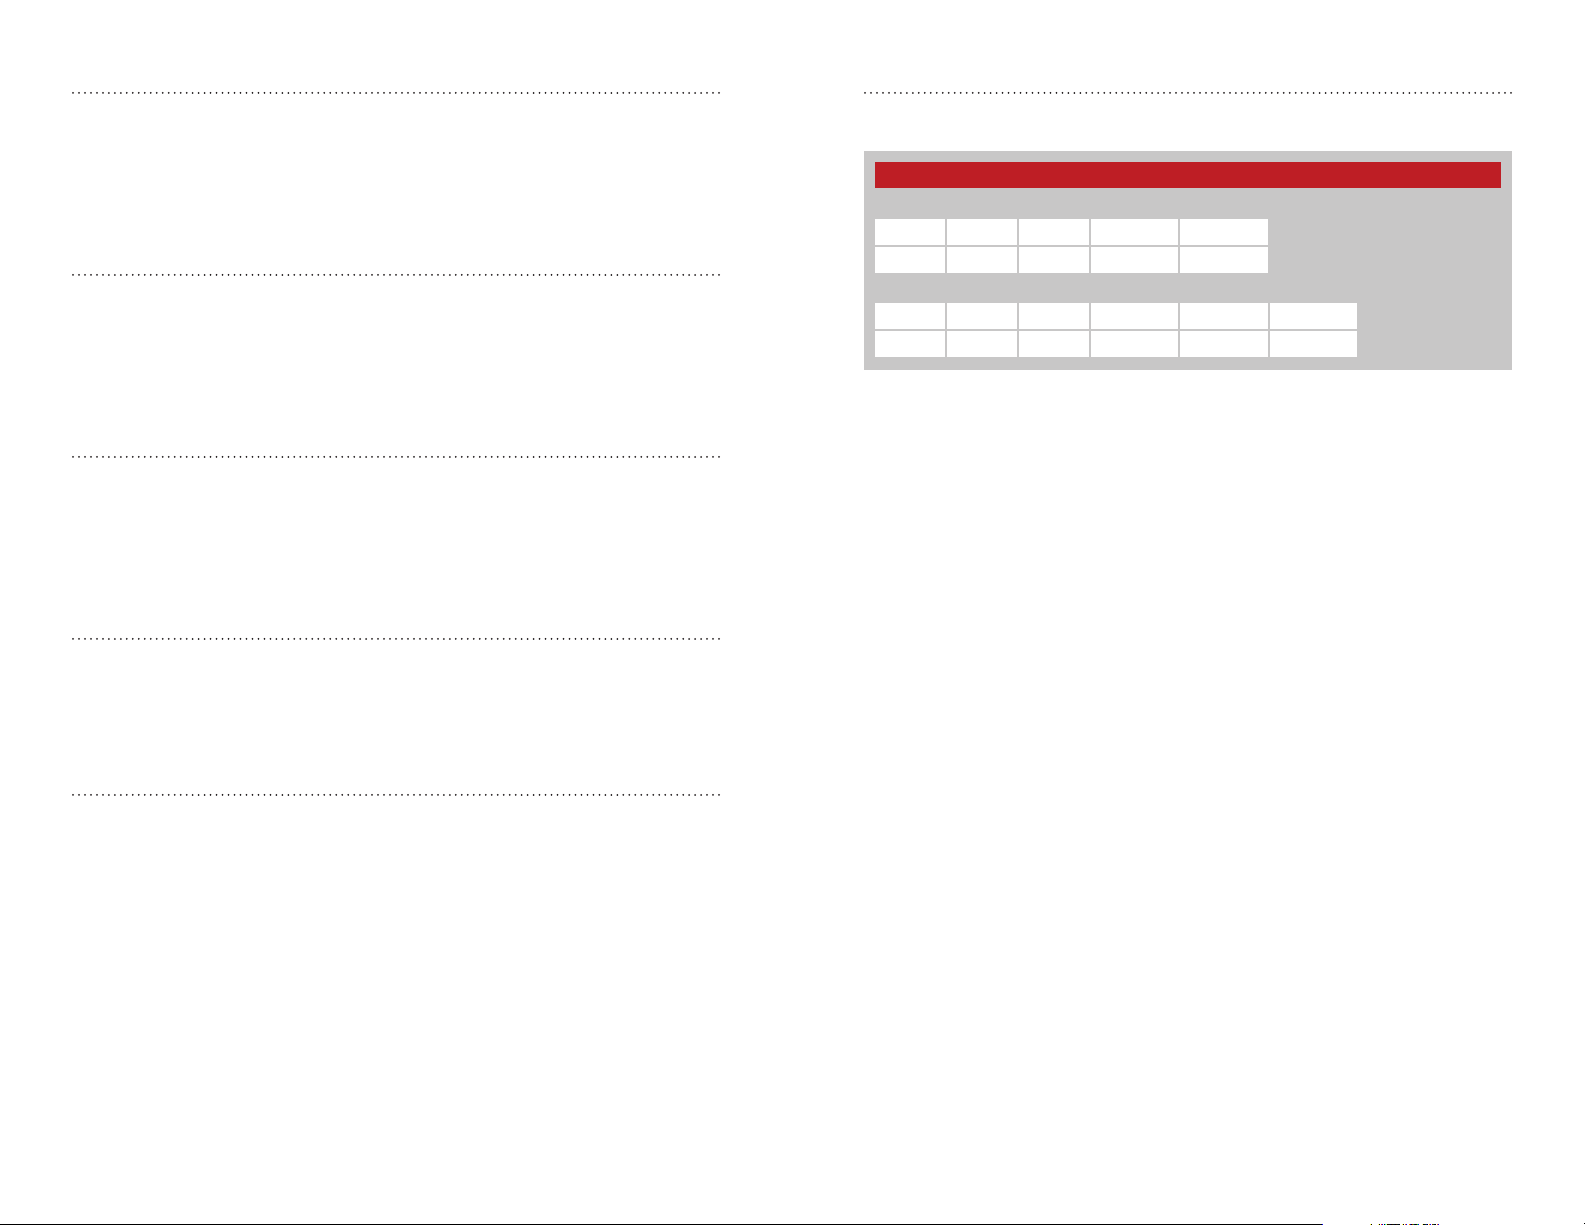
220 – Position Fix Interval
This command sets the position fix interval. This is the time between when
the module calculates its position. This is the same as write message 300.
Position Fix Interval Command and Response
Command
Start Msg ID Interval Checksum End
$PMTK 220 ,Ival *Cksum <CR><LF>
Response
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,220 ,Flg *Cksum <CR><LF>
$PMTK102*31<CR><LF>
103 – Cold Re-start
This command instructs the module to conduct a cold re-start that does
not use any of the data from memory. Periodic mode and static navigation
settings are returned to default when this command is executed.
$PMTK103*30<CR><LF>
104 – Restore Default Configuration
This command instructs the module to conduct a cold re-start and return
all configurations to the factory default settings.
$PMTK104*37<CR><LF>
161 – Standby Mode
This command instructs the module to enter a low power standby mode.
Any activity on the RX line wakes the module.
$PMTK161,0*28<CR><LF>
The module outputs the startup message when it wakes up.
Figure 22: Position Fix Interval Command and Response
Ival = the interval time in milliseconds.
The interval must be larger than 100ms. Faster rates require that the baud
rate be increased, the number of messages that are output be decreased
or both. The module automatically calculates the required data bandwidth
and returns an action failed response (Flg = 2) if the interval is faster than
the module can output all of the required messages at the current baud
rate. The following example sets the interval to 1 second.
$PMTK220,1000*1F<CR><LF>
$PMTK010,001*2E<CR><LF>
– –
20 21
– –
Page 14
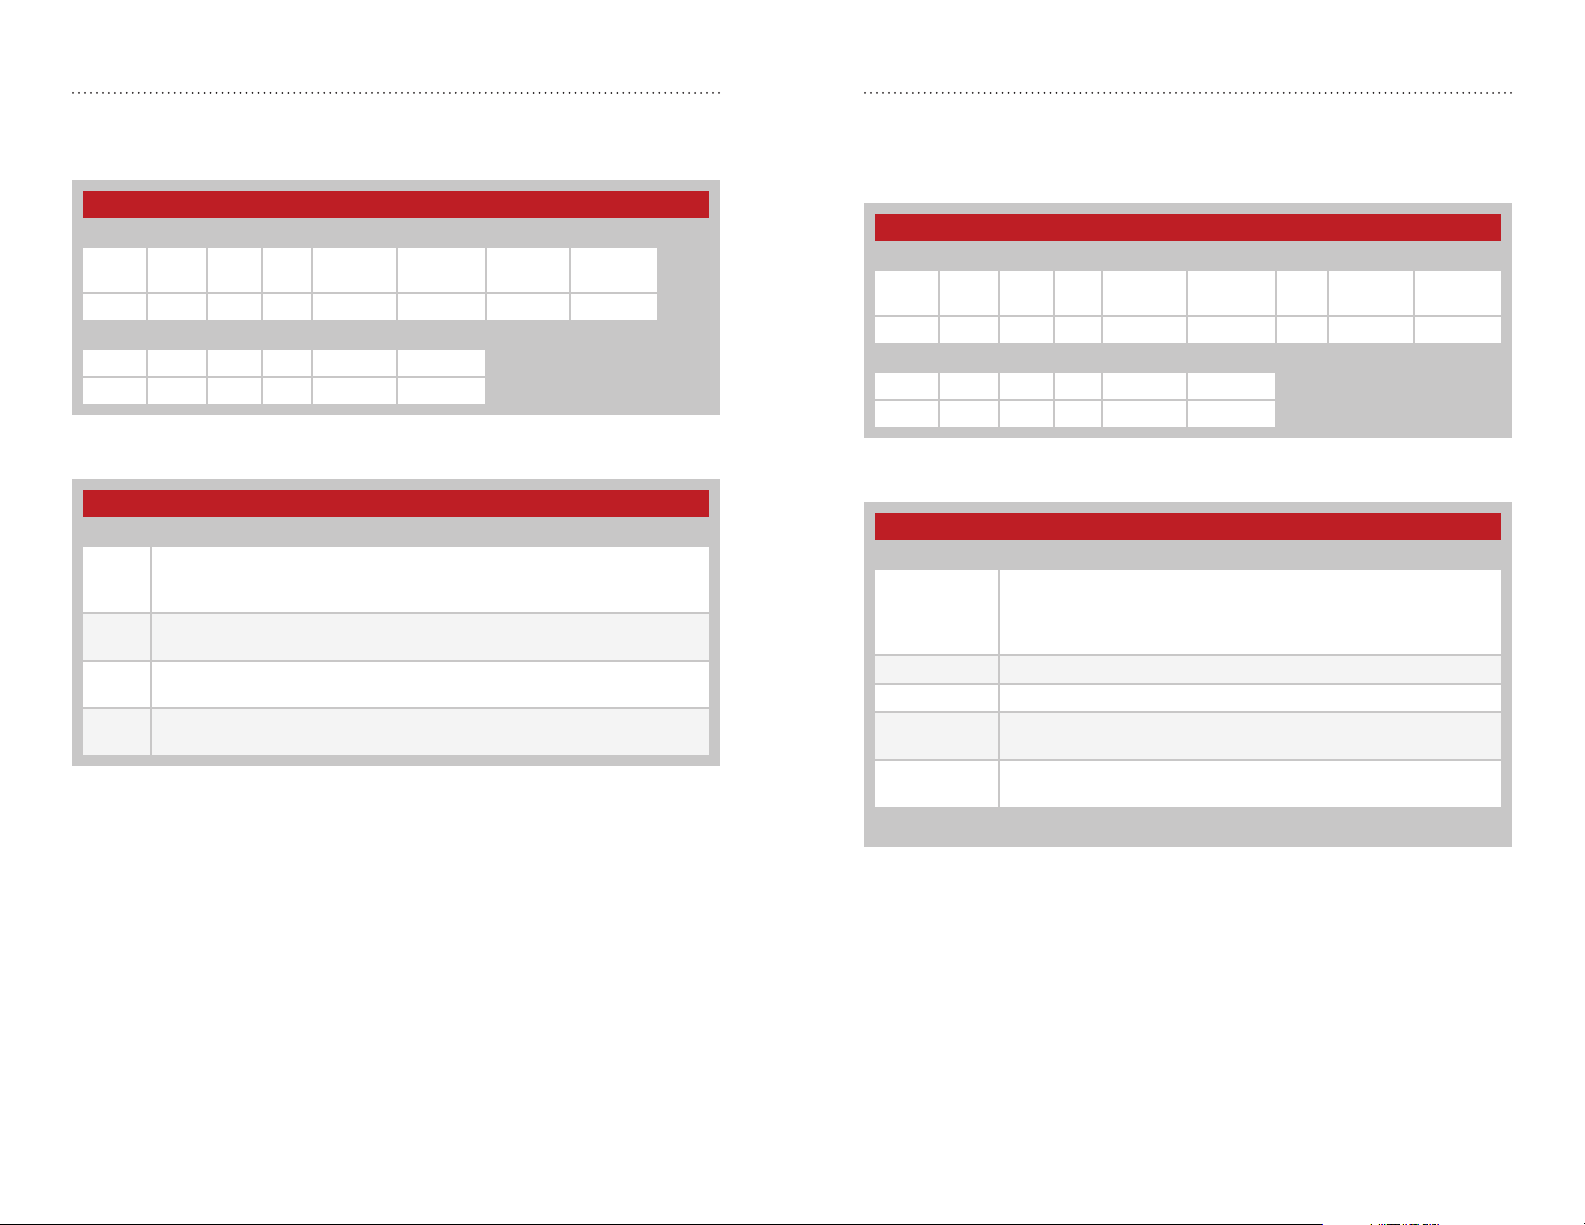
223 – Extended Receive Time
This command extends the amount of time that the receiver is on when in
duty cycle mode. This allows the module to refresh its stored ephemeris
data by staying awake until it received the data from the satellites.
Extended Receive Time Command and Response
Command
On
Start Msg ID SV
$PMTK 223 ,SV ,SNR ,EXT ,EXG *Cksum <CR><LF>
Response
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,223 ,Flg *Cksum <CR><LF>
Figure 23: Extended Receive Time Command and Response
Extended Receive Time Fields
Field Description
SV
SNR
EXT
EXG
Figure 24: Extended Receive Time Fields
The minimum number of satellites required to have valid ephemeris data. The
extend time triggers when the number of satellites with valid ephemeris data
falls below this number. The value is 1 to 4.
The minimum SNR of the satellites used for a position fix. The module will not
wait for ephemeris data from any satellites whose SNR is below this value.
The extended time in ms to stay on to receive ephemeris data. This value can
range from 40000 to 180000.
The minimum time in ms between a subsequent extended receive period. This
value can range from 0 to 3600000.
Time
Extend
Time
Extend
Gap
Checksum End
The following example configures an extended on time to trigger if less
than 1 satellite has valid ephemeris data. The satellite must have a signal to
noise ratio higher than 30dB–Hz in order to be used. The module will stay
on for 180,000ms and will have a gap time of 60,000ms.
$PMTK223,1,30,180000,60000*16<CR><LF>
225 – Receiver Duty Cycle
This command places the module into a duty cycle where it stays on for
a period of time and calculates it position then goes to sleep for a period
of time. This conserves battery power without the need for an external
microcontroller to manage the timing.
Receiver Duty Cycle Command and Response
Command
On
Start Msg ID Mode
$PMTK 225 ,Mde ,TO ,TS ,CO ,CS *Cksum <CR><LF>
Response
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,225 ,Flg *Cksum <CR><LF>
Figure 25: Receiver Duty Cycle Command and Response
Receiver Duty Cycle Fields
Field Description
Operation Mode
Mde
TO Receiver on time (ms)
TS Receiver standby time (ms)
CO
CS
CR and CS can be null values. In this case the module uses the TO and TS values.
Figure 26: Receiver Duty Cycle Fields
0 = Normal Mode
2 = Duty Cycle Mode
8 = AlwaysLocate
Receiver on time in the event of a cold start (ms). Allows more time for
the module to receive ephemeris data in the event of a cold start.
Receiver off time in the event of a cold start (ms). Allows more time for
the module to receive ephemeris data in the event of a cold start.
Time
Standby
Time
TM
Cold On
Cold
Checksum End
Sleep
This example sets the mode to duty cycle with an on time of 3s, and off
time of 12s, a cold start on time of 18s and a cold start off time of 72s.
$PMTK225,2,3000,12000,18000,72000*15<CR><LF>
The following example sets the mode to normal operation.
$PMTK225,0*2B<CR><LF>
The following example sets the module into AlwaysLocateTM mode.
$PMTK225,8*23<CR><LF>
– –
22 23
– –
Page 15
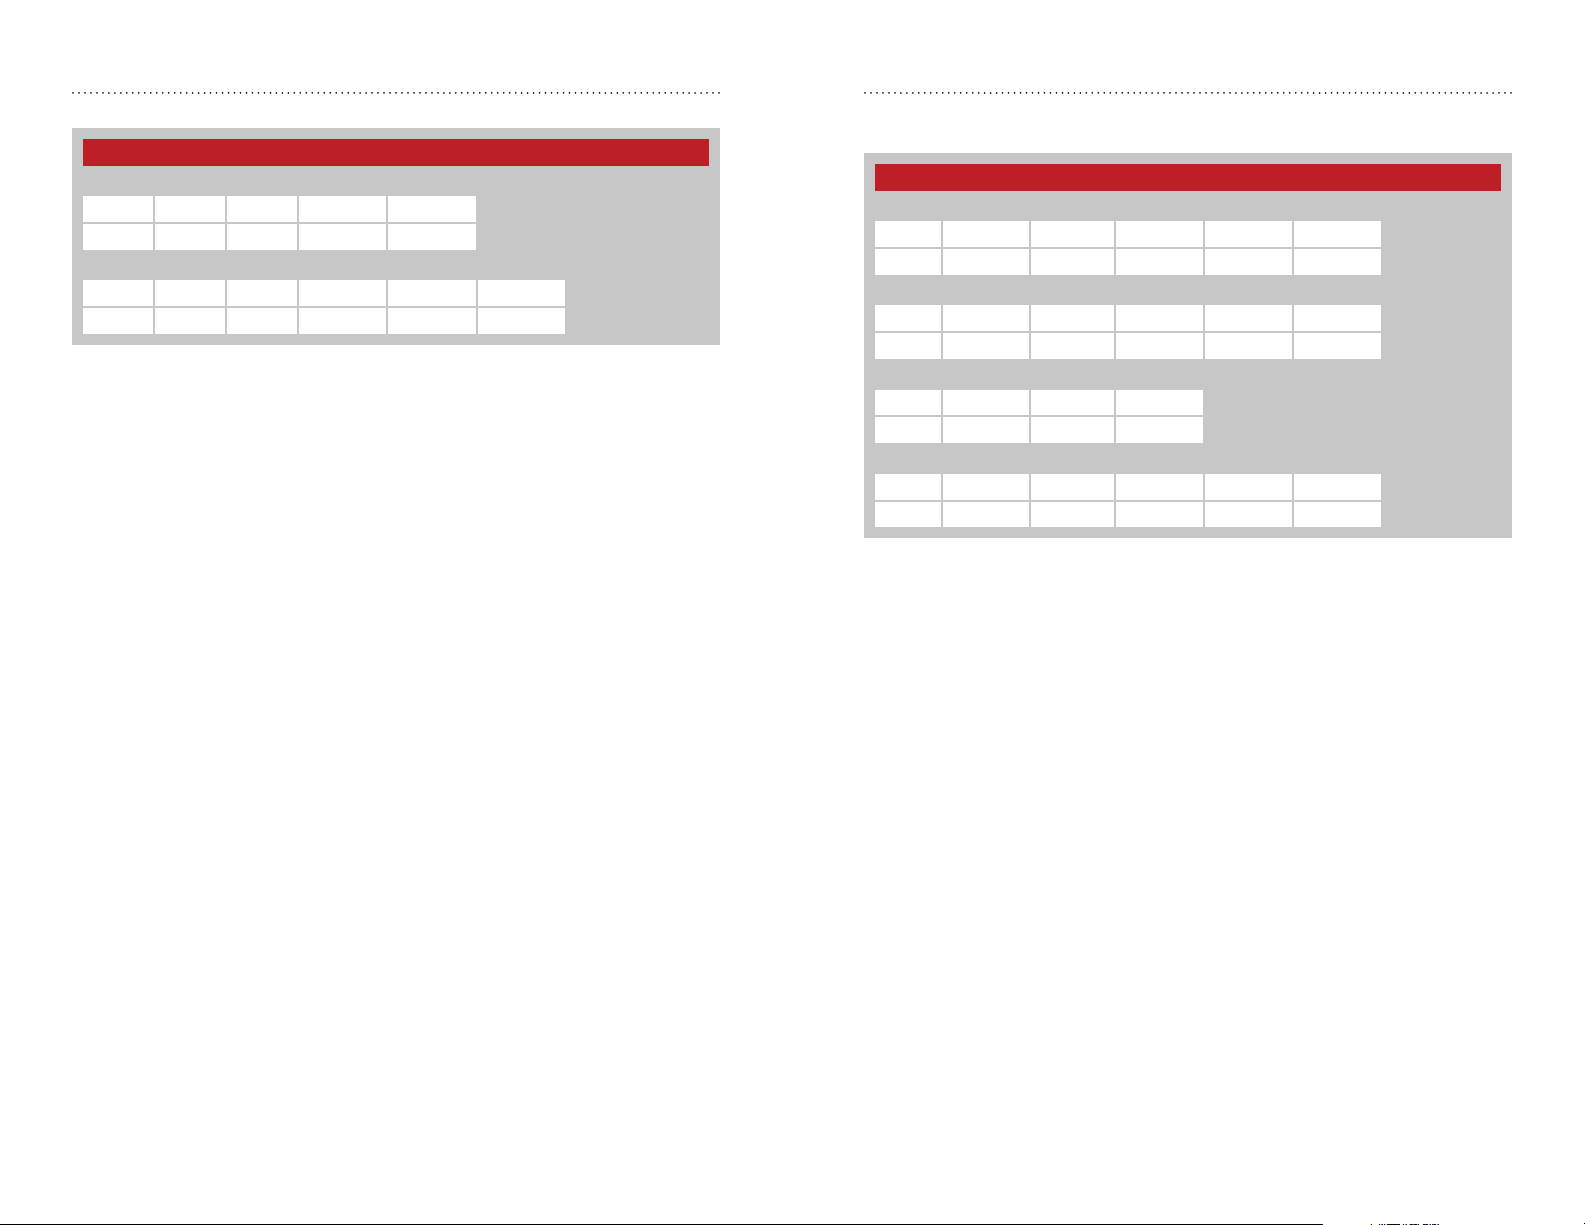
251 – Baud Rate
This command sets the serial port baud rate.
Serial Port Baud Rate Command and Response
Command
Start Msg ID Rate Checksum End
$PMTK 251 ,Rate *Cksum <CR><LF>
Response
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,251 ,Flg *Cksum <CR><LF>
Figure 27: Serial Port Baud Rate Command and Response
Rate = serial port baud rate
0 = default setting (9,600bps)
4800
9600
14400
19200
38400
57600
115200
The following example sets the baud rate to 57,600bps.
$PMTK251,57600*2C<CR><LF>
Position Fix Interval
This configures the position fix interval. This is the time between when the
module calculates its position. This is the same as write message 220.
Position Fix Interval Command and Response
Write Message
Start Msg ID Interval Data Checksum End
$PMTK 300 ,Ival ,0,0,0,0 *Cksum <CR><LF>
Acknowledge Response Message
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,300 ,Flg *Cksum <CR><LF>
Read Message
Start Msg ID Checksum End
$PMTK 400 *36 <CR><LF>
Response Message
Start Msg ID Interval Data Checksum End
$PMTK 500 ,Ival ,0,0,0,0 *Cksum <CR><LF>
Figure 28: Position Fix Interval Command and Response
Ival = the interval time in milliseconds.
The interval must be larger than 100ms. Faster rates require that the baud
rate be increased, the number of messages that are output be decreased
or both. The module automatically calculates the required data bandwidth
and returns an action failed response (Flg = 2) if the interval is faster than
the module can output all of the required messages at the current baud
rate.
The following example sets the interval to 1 second.
$PMTK300,1000,0,0,0,0*1C<CR><LF>
The following example reads the current position fix interval and the module
responds with an interval time of 1 second (1,000ms)
$PMTK400*36<CR><LF>
$PMTK500,1000,0,0,0,0*1A<CR><LF>
– –
24 25
– –
Page 16
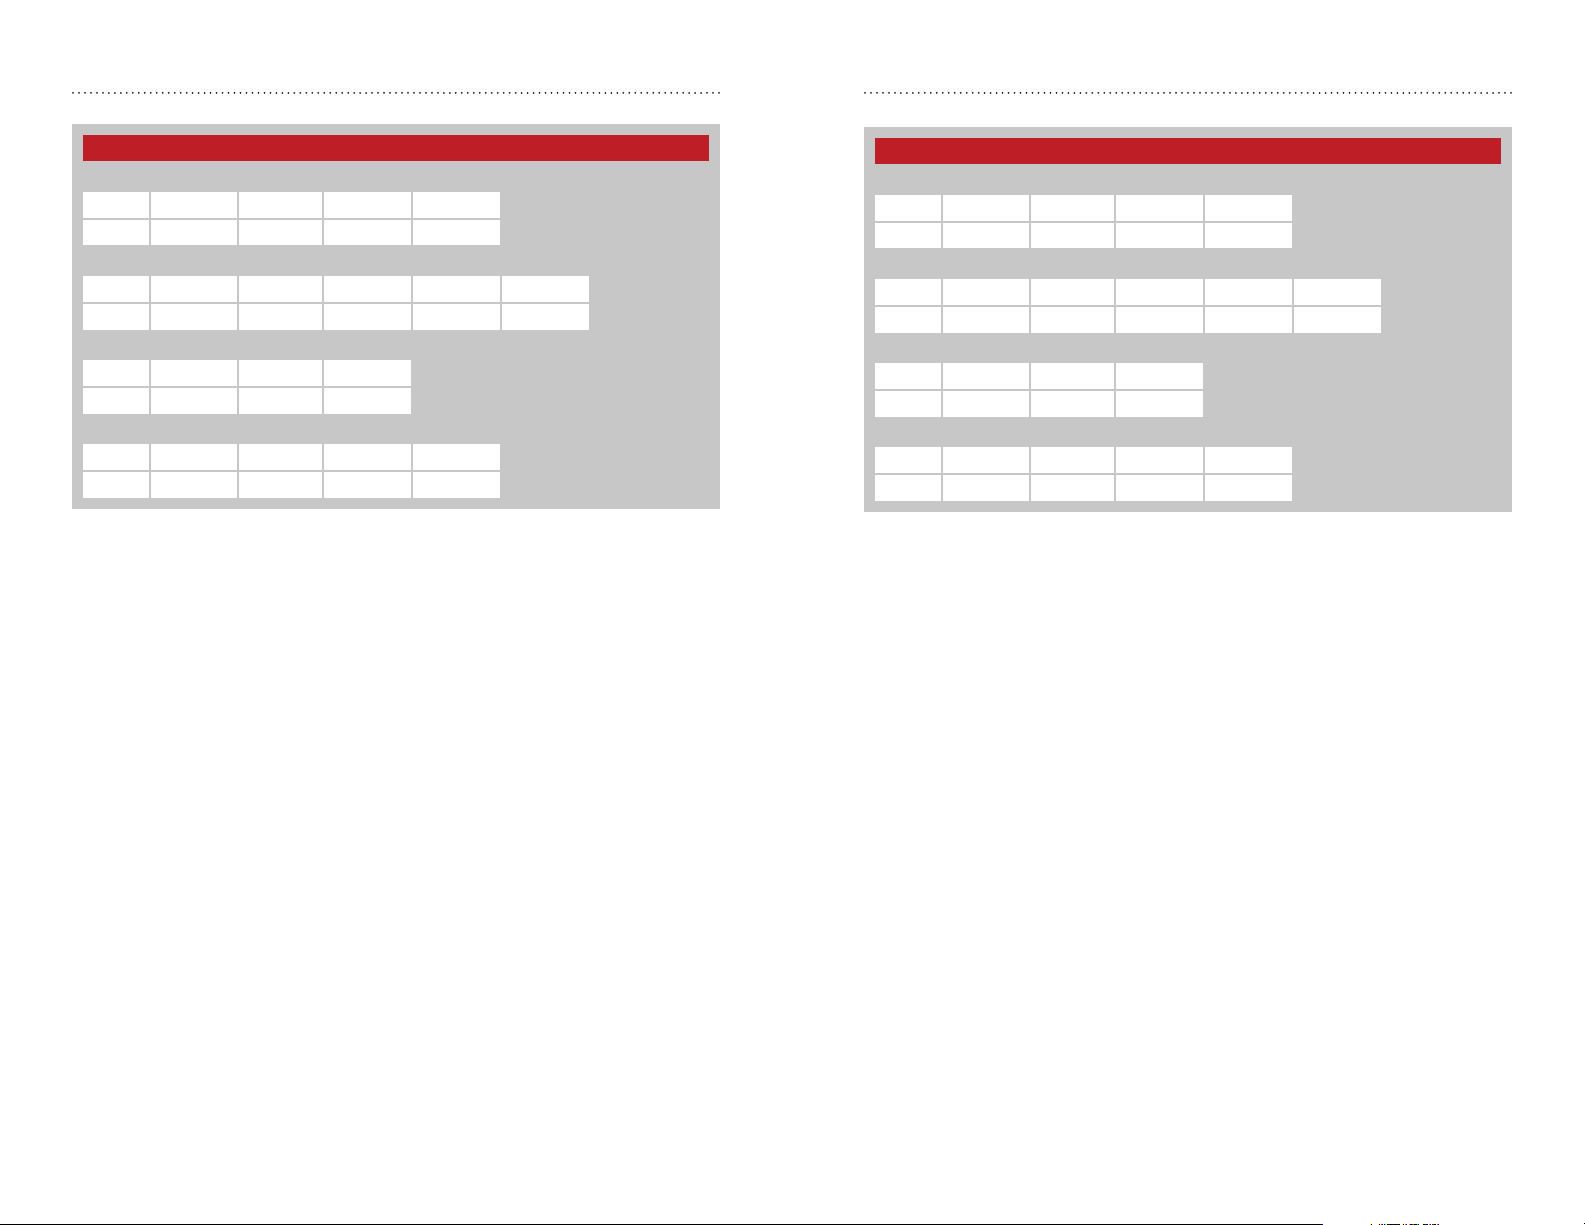
DGPS Source
This enables or disables DGPS mode and configures its source.
SBAS Enable
This enables and disables SBAS.
DGPS Souce Command and Response
Write Message
Start Msg ID Mode Checksum End
$PMTK 301 ,Mode *Cksum <CR><LF>
Acknowledge Response Message
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,301 ,Flg *Cksum <CR><LF>
Read Message
Start Msg ID Checksum End
$PMTK 401 *37 <CR><LF>
Response Message
Start Msg ID Mode Checksum End
$PMTK 501 ,Mode *Cksum <CR><LF>
Figure 29: DGPS Source Command and Response
Mode = DGPS source mode
0 = No DGPS source
1 = RTCM
2 = WAAS
Differential Global Positioning System (DGPS) enhances GPS by using
fixed, ground-based reference stations that broadcast the difference
between the positions indicated by the satellite systems and the known
fixed positions. The Radio Technical Commission for Maritime Services
(RTCM) is an international standards organization that has a standard for
DGPS. Wide Area Augmentation System (WAAS) is maintained by the FAA
to improve aircraft navigation. This setting automatically switches among
WAAS, EGNOS, MSAS and GAGAN when detected in covered regions
SBAS Enable Command and Response
Write Message
Start Msg ID Mode Checksum End
$PMTK 313 ,Mode *Cksum <CR><LF>
Acknowledge Response Message
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,313 ,Flg *Cksum <CR><LF>
Read Message
Start Msg ID Checksum End
$PMTK 413 *34 <CR><LF>
Response Message
Start Msg ID Mode Checksum End
$PMTK 513 ,Mode *Cksum <CR><LF>
Figure 30: SBAS Enable Command and Response
Mode = SBAS Mode
0 = disabled
1 = enabled
A satellite-based augmentation system (SBAS) sends additional information
in the satellite transmissions to improve accuracy and reliability. Ground
stations at accurately surveyed locations measure the satellite signals or
other environmental factors that may impact the signal received by users.
Correction information is then sent to the satellites and broadcast to the
users. Disabling this feature also disables automatic DGPS.
The following example enables SBAS.
The following example sets the DGPS source to RTCM.
$PMTK301,1*2D<CR><LF>
The following example reads the current DGPS source and the module
responds with the DGPS source as RTCM.
$PMTK401*37<CR><LF>
$PMTK501,1*2B<CR><LF>
– –
26 27
$PMTK313,1*2E<CR><LF>
The following example reads the current SBAS configuration and the
module responds with SBAS is enabled.
$PMTK413*34<CR><LF>
$PMTK513,1*28<CR><LF>
– –
Page 17
NMEA Output Messages
This configures how often each NMEA output message is output.
Set Datum
This configures the current datum that is used.
NMEA Output Messages Command and Response
Write Message
Msg
Start
$PMTK 314 ,GLL ,RMC ,VTG ,GGA ,GSA ,GSV ,0,0,0,0,0,0,0,0,0,0,0,0,0, *CK <CR><LF>
Acknowledge Response Message
Start
$PMTK 001 ,314 ,Flg *CK <CR><LF>
Read Message
Start
$PMTK 414 *33 <CR><LF>
Response Message
Start
$PMTK 514 ,GLL ,RMC ,VTG ,GGA ,GSA ,GSV ,0,0,0,0,0,0,0,0,0,0,0,0,0, *CK <CR><LF>
Figure 31: NMEA Output Messages Command and Response
GLL RMC VTG GGA GSA GSV DATA CK End
ID
Msg
CMD Flag CK End
ID
Msg
CK End
ID
Msg
GLL RMC VTG GGA GSA GSV DATA CK End
ID
Each field has a value of 1 through 5 which indicates how many position
fixes should be between each time the message is output. A 1 configures
the message to be output every position fix. A value of 2 configures the
message to be output every other position fix and a value of 5 configures
it to be output every 5th position fix. This along with message 220 or 300
sets the time between message outputs.
Set Datum Command and Response
Write Message
Start Msg ID Datum Checksum End
$PMTK 330 ,Datum *Cksum <CR><LF>
Acknowledge Response Message
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,330 ,Flg *Cksum <CR><LF>
Read Message
Start Msg ID Checksum End
$PMTK 430 *35 <CR><LF>
Response Message
Start Msg ID Datum Checksum End
$PMTK 530 ,Datum *Cksum <CR><LF>
Figure 32: Set Datum Command and Response
Datum = the datum number to be used.
Reference datums are data sets that describe the shape of the Earth
based on a reference point. There are many regional datums based on a
convenient local reference point. Different datums use different reference
points, so a map used with the receiver output must be based on the same
datum. WGS84 is the default world referencing datum.
The module supports 223 different datums. These are listed in Appendix A.
A value of 0 disables the message.
The example below sets all of the messages to be output every fix.
$PMTK314,1,1,1,1,1,1,0,0,0,0,0,0,0,0,0,0,0,0,0*28<CR><LF>
The following example reads the current message configuration and the
module responds that all supported messages are configured to be output
on every position fix.
$PMTK414*33<CR><LF>
$PMTK514,1,1,1,1,1,1,0,0,0,0,0,0,0,0,0,0,0,0,0*2E<CR><LF>
– –
28 29
The following example sets the datum to WGS84.
$PMTK330,0*2E<CR><LF>
The following example reads the current datum and the module replies with
datum 0, which is WGS84.
$PMTK430*35<CR><LF>
$PMTK530,0*28<CR><LF>
– –
Page 18
Static Navigation Threshold
This configures the speed threshold to trigger static navigation. If the
measured speed is below the threshold then the module holds the current
position and sets the speed to zero.
Static Navigation Threshold Command and Response
Write Message
Start Msg ID Thold Checksum End
$PMTK 386 ,Thold *Cksum <CR><LF>
Acknowledge Response Message
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,386 ,Flg *Cksum <CR><LF>
Read Message
Start Msg ID Checksum End
$PMTK 447 *35 <CR><LF>
Response Message
Start Msg ID Thold Checksum End
$PMTK 527 ,Thold *Cksum <CR><LF>
Enable Ephemeris Prediction
This enables or disables the module’s built-in ephemeris prediction.
Enable Ephemeris Prediction Command and Response
Write Message
Start Msg ID CMD Enable Checksum End
$PMTK 869 ,1 ,Enable *Cksum <CR><LF>
Acknowledge Response Message
Start Msg ID CMD Flag Checksum End
$PMTK 001 ,869 ,Flg *Cksum <CR><LF>
Read Message
Start Msg ID CMD Enable Checksum End
$PMTK 869 ,0 ,Enable *Cksum <CR><LF>
Response Message
Start Msg ID CMD Enable Checksum End
$PMTK 869 ,2 ,Enable *Cksum <CR><LF>
Figure 34: Enable Ephemeris Prediction Command and Response
Figure 33: Static Navigation Threshold Command and Response
Thold = speed threshold, from 0 to 2.0m/s. 0 = disabled.
The following example sets the threshold to 1.2m/s.
$PMTK386,1.2*3E<CR><LF>
The following example reads the static navigation threshold and the module
responds with 1.2m/s
$PMTK447*35<CR><LF>
$PMTK527,1.20*03<CR><LF>
This message is formatted slightly differently from the other messages. The
same Message ID is used for the read, write and response and the first
payload field (CMD) indicates which type of message it is. A 0 is a read, a 1
is a write and a 2 is a response to a read.
Enable = enable ephemeris prediction
0 = disabled
1 = enabled
The following example enables prediction.
$PMTK869,1,1*35<CR><LF>
The following example reads the configuration.
$PMTK869,0*29<CR><LF>
The module responds with the first example if prediction is disabled and the
second if it is enabled.
$PMTK869,2,0*37<CR><LF>
$PMTK869,2,1*36<CR><LF>
– –
30 31
– –
Page 19
Typical Applications
VCC
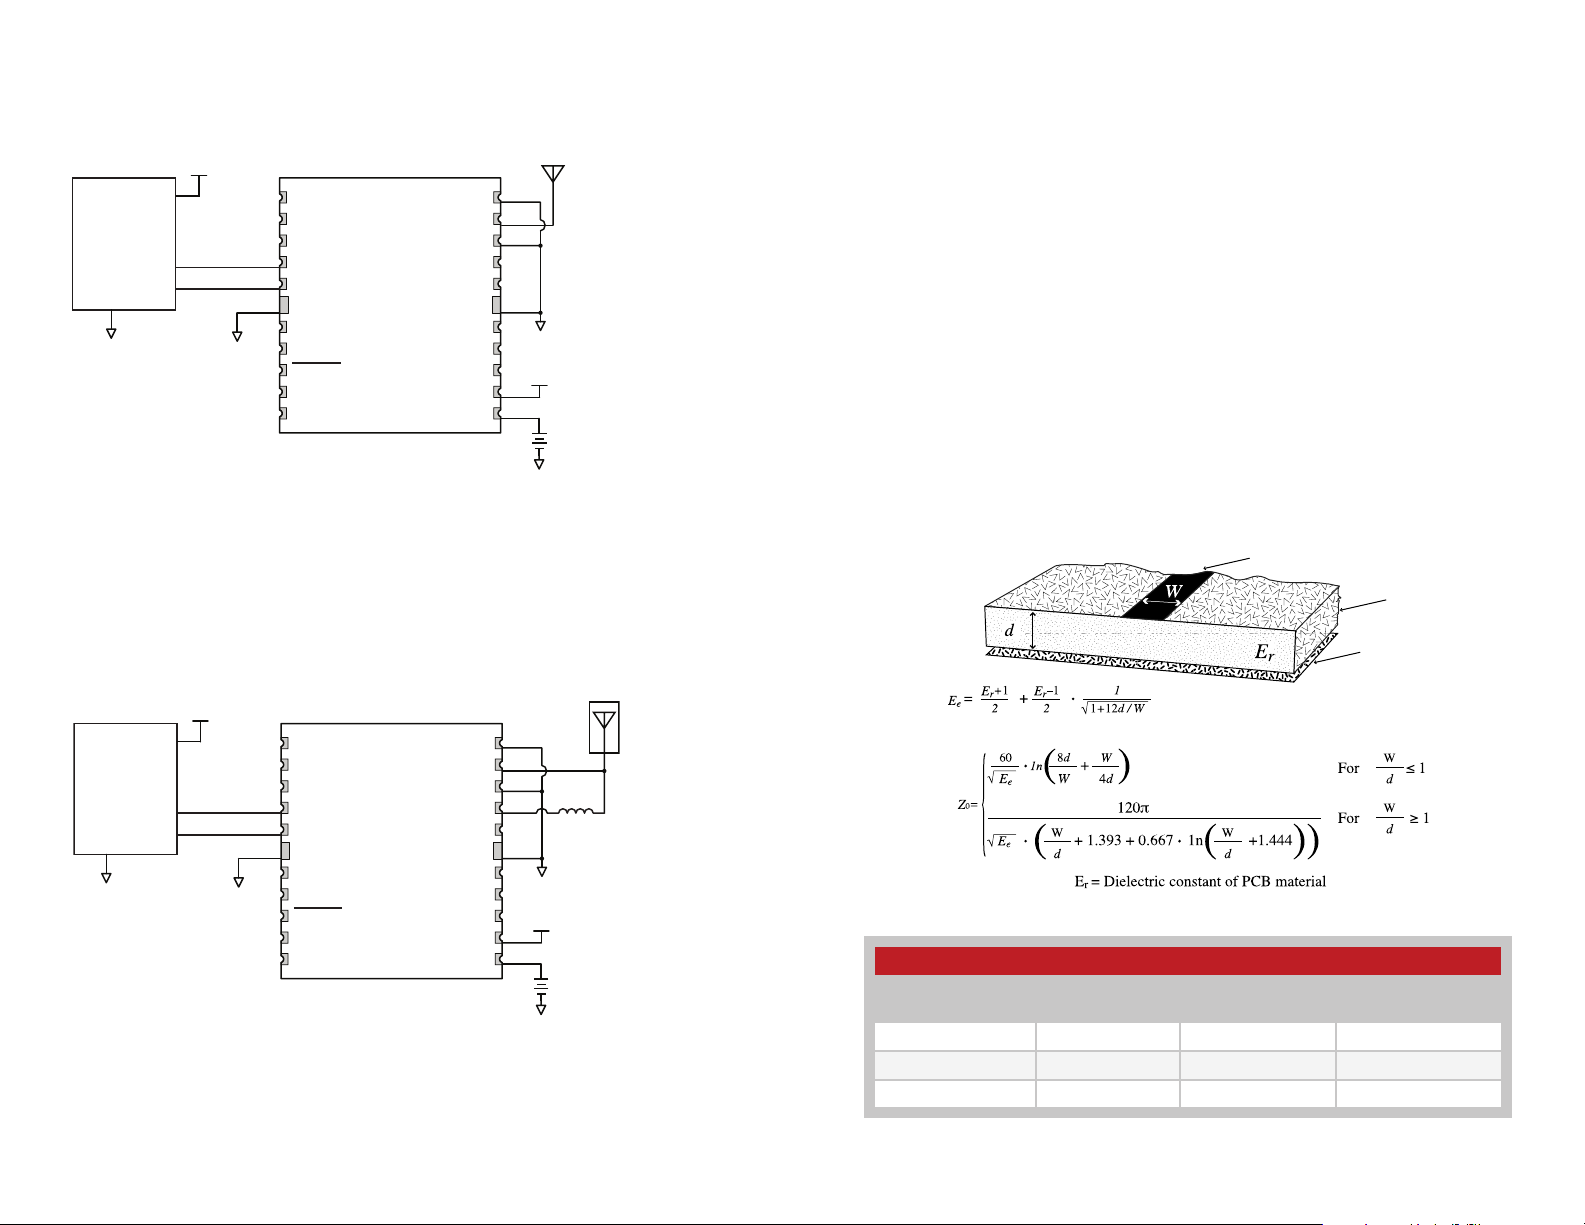
Figure 35 shows the FM Series GPS receiver in a typical application using a
passive antenna.
GND
1
2
3
4
5
21
6
7
8
9
10
NC
NC
1PPS
TX
RX
GND
NC
NC
RESET
NC
NC
VBACKUP
µP
GND
GND
VCC
RX
TX
Figure 35: Circuit Using the FM Series Module with a Passive Antenna
A microcontroller UART is connected to the receiver’s UART for passing
data and commands. A 3.3V coin cell battery is connected to the
VBACKUP line to provide power to the module’s memory when main
power is turned off.
GND
RFIN
GND
VOUT
NC
GND
NC
NC
NC
VCC
20
19
18
17
16
22
15
14
13
12
11
GND
VCC
GND
Microstrip Details
A transmission line is a medium whereby RF energy is transferred from
one place to another with minimal loss. This is a critical factor, especially in
high-frequency products like Linx RF modules, because the trace leading
to the module’s antenna can effectively contribute to the length of the
antenna, changing its resonant bandwidth. In order to minimize loss and
detuning, some form of transmission line between the antenna and the
module should be used unless the antenna can be placed very close (<1⁄8in)
to the module. One common form of transmission line is a coax cable and
another is the microstrip. This term refers to a PCB trace running over a
ground plane that is designed to serve as a transmission line between the
module and the antenna. The width is based on the desired characteristic
impedance of the line, the thickness of the PCB and the dielectric constant
of the board material. For standard 0.062in thick FR-4 board material, the
trace width would be 111 mils. The correct trace width can be calculated
for other widths and materials using the information in Figure 37 and
examples are provided in Figure 38. Software for calculating microstrip lines
is also available on the Linx website.
Trace
Board
Ground plane
Figure 36 shows the module using an active antenna.
VCC
µP
GND
GND
VCC
RX
TX
GND
1
2
3
4
5
21
6
7
8
9
10
NC
NC
1PPS
TX
RX
GND
NC
NC
RESET
NC
NC
VBACKUP
GND
RFIN
GND
VOUT
NC
GND
NC
NC
NC
VCC
20
19
18
17
16
22
15
14
13
12
11
Ferrite Bead
GND
VCC
GND
300Ω
Figure 36: Circuit Using the FM Series Module with a an Active Antenna
A 300Ω ferrite bead is used to put power from VOUT onto the antenna line
to power the active antenna.
– –
32 33
Figure 37: Microstrip Formulas
Example Microstrip Calculations
Dielectric Constant
Width/Height
Ratio (W/d)
4.80 1.8 3.59 50.0
4.00 2.0 3.07 51.0
2.55 3.0 2.12 48.0
Figure 38: Example Microstrip Calculations
Effective Dielectric
Constant
– –
Characteristic
Impedance (Ω)
Page 20
Board Layout Guidelines
The module’s design makes integration straightforward; however, it
is still critical to exercise care in PCB layout. Failure to observe good
layout techniques can result in a significant degradation of the module’s
performance. A primary layout goal is to maintain a characteristic
50-ohm impedance throughout the path from the antenna to the module.
Grounding, filtering, decoupling, routing and PCB stack-up are also
important considerations for any RF design. The following section provides
some basic design guidelines which may be helpful.
During prototyping, the module should be soldered to a properly laid-out
circuit board. The use of prototyping or “perf” boards will result in poor
performance and is strongly discouraged.
The module should, as much as reasonably possible, be isolated from
other components on your PCB, especially high-frequency circuitry such as
crystal oscillators, switching power supplies, and high-speed bus lines.
Each of the module’s ground pins should have short traces tying
immediately to the ground plane through a via.
Bypass caps should be low ESR ceramic types and located directly
adjacent to the pin they are serving.
A 50-ohm coax should be used for connection to an external antenna.
A 50-ohm transmission line, such as a microstrip, stripline or coplanar
waveguide should be used for routing RF on the PCB. The Microstrip
Details section provides additional information.
In some instances, a designer may wish to encapsulate or “pot” the
product. There is a wide variety of potting compounds with varying
dielectric properties. Since such compounds can considerably impact
RF performance and the ability to rework or service the product, it is
the responsibility of the designer to evaluate and qualify the impact and
suitability of such materials.
When possible, separate RF and digital circuits into different PCB regions.
Make sure internal wiring is routed away from the module and antenna, and
is secured to prevent displacement.
Do not route PCB traces directly under the module. There should not be
any copper or traces under the module on the same layer as the module,
just bare PCB. The underside of the module has traces and vias that could
short or couple to traces on the product’s circuit board.
The Pad Layout section shows a typical PCB footprint for the module. A
ground plane (as large and uninterrupted as possible) should be placed on
a lower layer of your PC board opposite the module. This plane is essential
for creating a low impedance return for ground and consistent stripline
performance.
Use care in routing the RF trace between the module and the antenna
or connector. Keep the trace as short as possible. Do not pass under
the module or any other component. Do not route the antenna trace on
multiple PCB layers as vias will add inductance. Vias are acceptable for
tying together ground layers and component grounds and should be used
in multiples.
Pad Layout
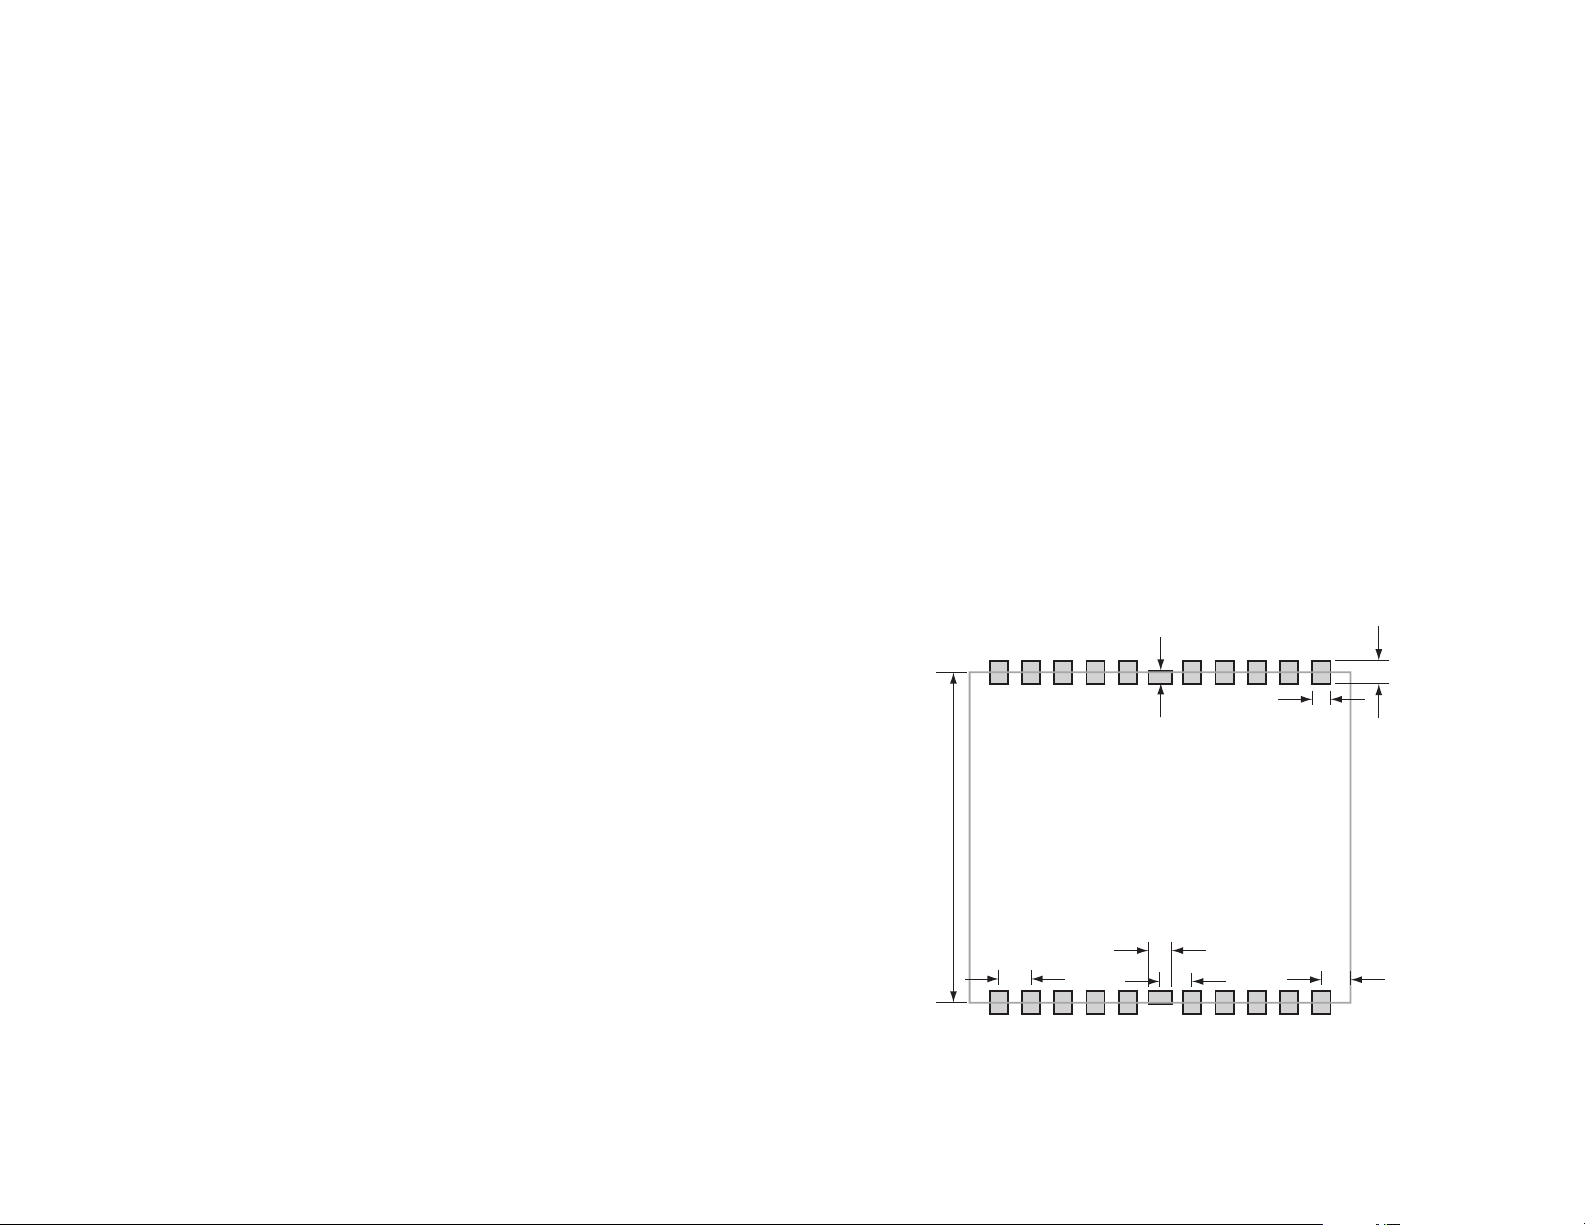
The pad layout diagram in Figure 39 is designed to facilitate both hand and
automated assembly.
0.036
(0.92)
0.020
(0.50)
0.028
(0.70)
0.512
(13.00)
0.036
0.050
(1.27)
Figure 39: Recommended PCB Layout
(0.92)
0.050
(1.27)
0.045
(1.15)
– –
34 35
– –
Page 21
Production Guidelines
The module is housed in a hybrid SMD package that supports hand and
automated assembly techniques. Since the modules contain discrete
components internally, the assembly procedures are critical to ensuring
the reliable function of the modules. The following procedures should be
reviewed with and practiced by all assembly personnel.
Hand Assembly
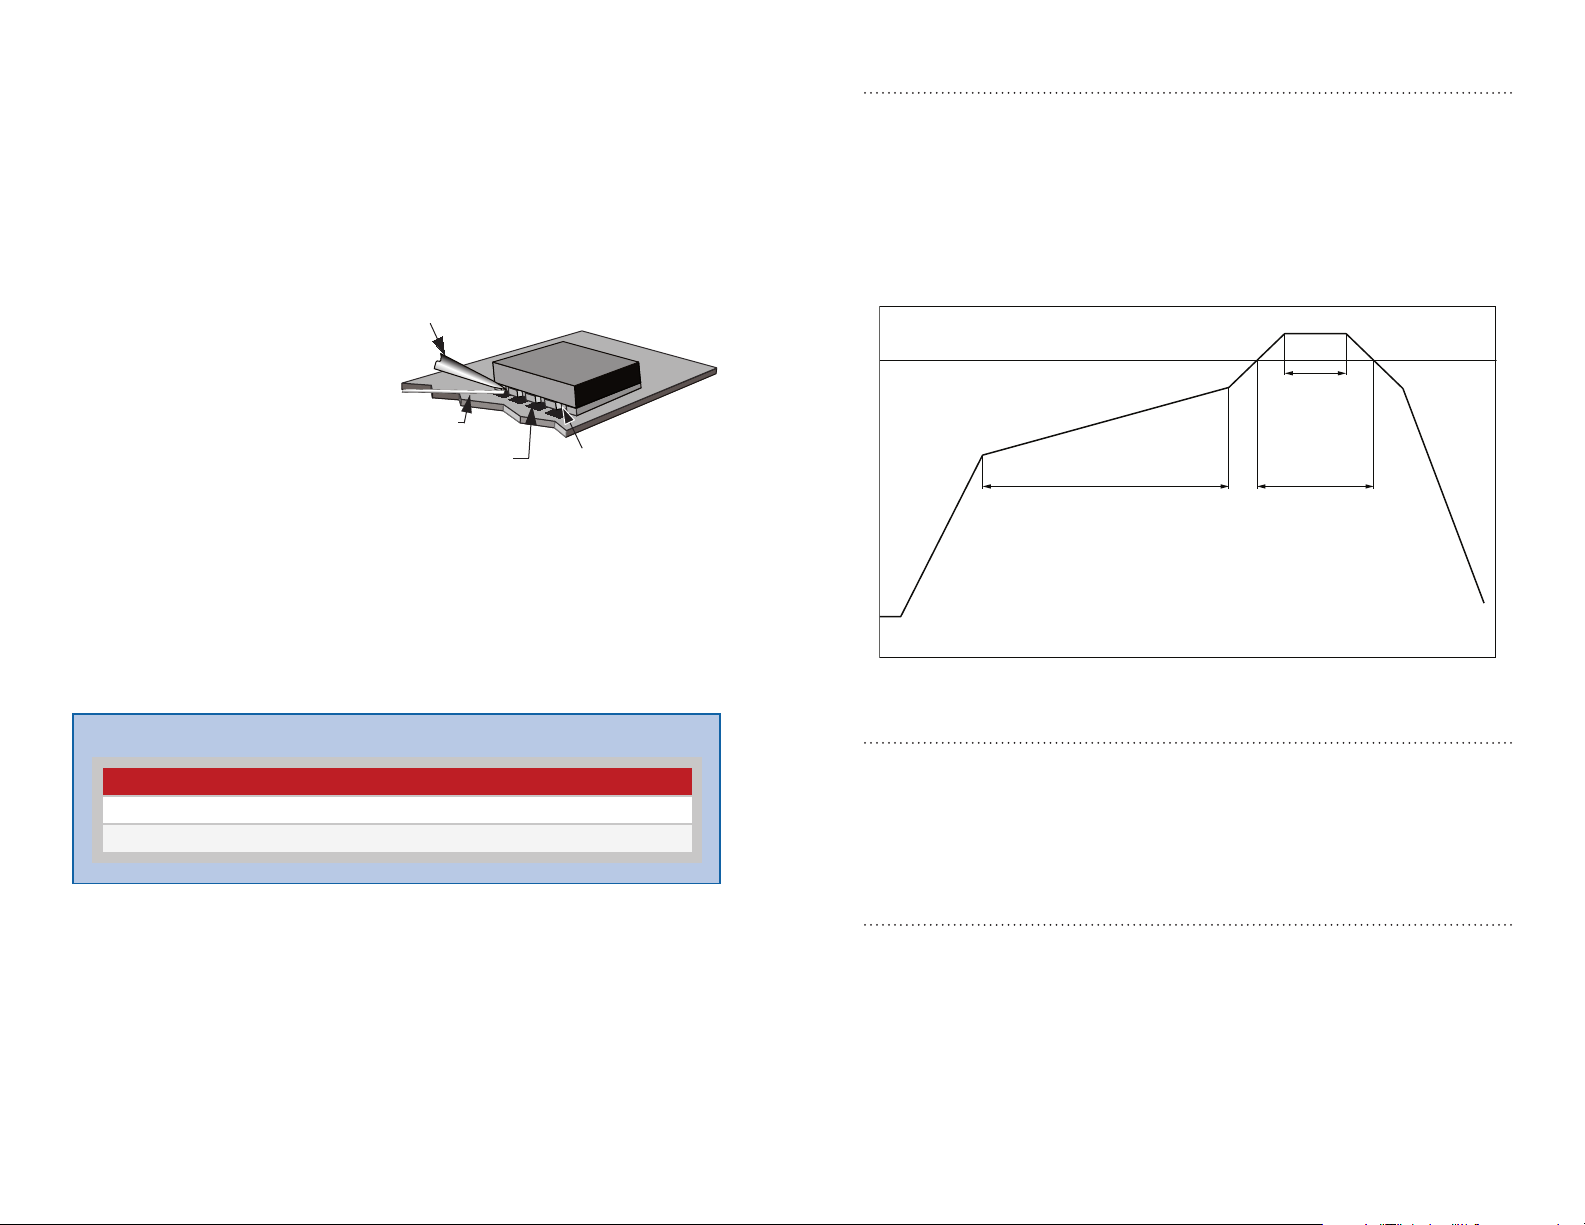
Pads located on the bottom
of the module are the primary
mounting surface (Figure 40).
Since these pads are inaccessible
during mounting, castellations
that run up the side of the module
have been provided to facilitate
solder wicking to the module’s
underside. This allows for very
quick hand soldering for prototyping and small volume production. If the
recommended pad guidelines have been followed, the pads will protrude
slightly past the edge of the module. Use a fine soldering tip to heat the
board pad and the castellation, then introduce solder to the pad at the
module’s edge. The solder will wick underneath the module, providing
reliable attachment. Tack one module corner first and then work around the
device, taking care not to exceed the times in Figure 41.
Soldering Iron
Tip
Solder
PCB Pads
Figure 40: Soldering Technique
Castellations
Reflow Temperature Profile
The single most critical stage in the automated assembly process is the
reflow stage. The reflow profile in Figure 42 should not be exceeded
because excessive temperatures or transport times during reflow will
irreparably damage the modules. Assembly personnel need to pay careful
attention to the oven’s profile to ensure that it meets the requirements
necessary to successfully reflow all components while still remaining
within the limits mandated by the modules. The figure below shows the
recommended reflow oven profile for the modules.
Peak: 240+0/-5°C
220°C
Preheat:
150 - 200°C
120 - 150sec
2 - 4°C/sec
30°C
Figure 42: Maximum Reflow Temperature Profile
2 - 3°C/sec
25 - 35sec
60 - 80sec
Warning: Pay attention to the absolute maximum solder times.
Absolute Maximum Solder Times
Hand Solder Temperature: +427ºC for 10 seconds for lead-free alloys
Reflow Oven: +240°C max (see Figure 42)
Figure 41: Absolute Maximum Solder Times
Automated Assembly
For high-volume assembly, the modules are generally auto-placed.
The modules have been designed to maintain compatibility with reflow
processing techniques; however, due to their hybrid nature, certain aspects
of the assembly process are far more critical than for other component
types. Following are brief discussions of the three primary areas where
caution must be observed.
– –
36 37
Shock During Reflow Transport
Since some internal module components may reflow along with the
components placed on the board being assembled, it is imperative that
the modules not be subjected to shock or vibration during the time solder
is liquid. Should a shock be applied, some internal components could be
lifted from their pads, causing the module to not function properly.
Washability
The modules are wash-resistant, but are not hermetically sealed. Linx
recommends wash-free manufacturing; however, the modules can be
subjected to a wash cycle provided that a drying time is allowed prior
to applying electrical power to the modules. The drying time should be
sufficient to allow any moisture that may have migrated into the module
to evaporate, thus eliminating the potential for shorting damage during
power-up or testing. If the wash contains contaminants, the performance
may be adversely affected, even after drying.
– –
Page 22
Master Development System
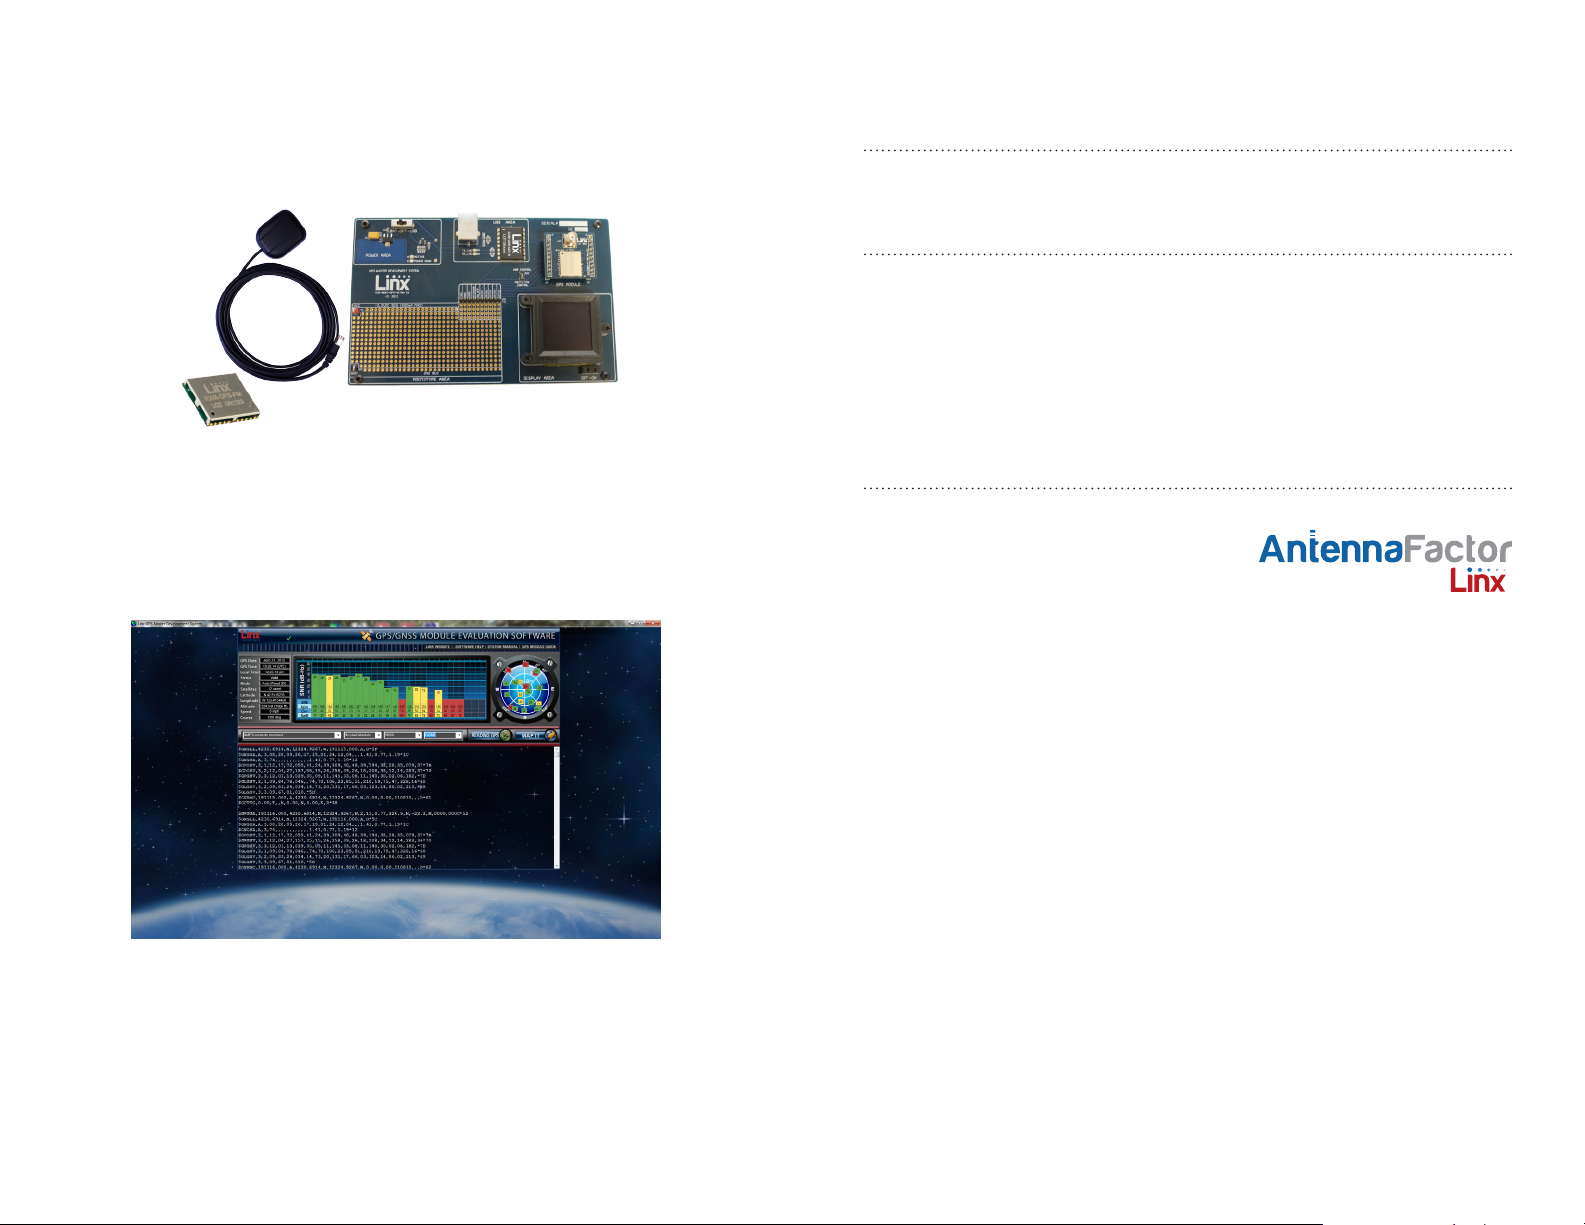
The FM Series Master Development System provides all of the tools
necessary to evaluate the FM Series GPS receiver module. The system
includes a fully assembled development board, an active antenna,
development software and full documentation.
Figure 43: The FM Series Master Development System
The development board includes a power supply, a prototyping area for
custom circuit development, and an OLED display that shows the GPS
data without the need for a computer. A USB interface is also included
for use with a PC running custom software or the included development
software.
Resources
Support
For technical support, product documentation, application notes, regulatory
guidelines and software updates, visit www.linxtechnologies.com
RF Design Services
For customers who need help implementing Linx modules, Linx offers
design services including board layout assistance, programming,
certification advice and packaging design. For more complex RF solutions,
Apex Wireless, a division of Linx Technologies, creates optimized designs
with RF components and firmware selected for the customer’s application.
Call +1 800 736 6677 (+1 541 471 6256 if outside the United States) for
more information.
Antenna Factor Antennas
Linx’s Antenna Factor division has the
industry’s broadest selection of antennas
for a wide variety of applications. For
customers with specialized needs,
custom antennas and design services are
available along with simulations of antenna
performance to speed development. Learn more at www.linxtechnologies.
com.
by
Figure 44: The Master Development System Software
The Master Development System software enables configuration of the
receiver and displays the satellite data output by the receiver. The software
can select from among all of the supported NMEA protocols for display of
the data.
Full documentation for the board and software is included in the
development system, making integration of the module straightforward.
– –
38 39
– –
Page 23
Appendix A
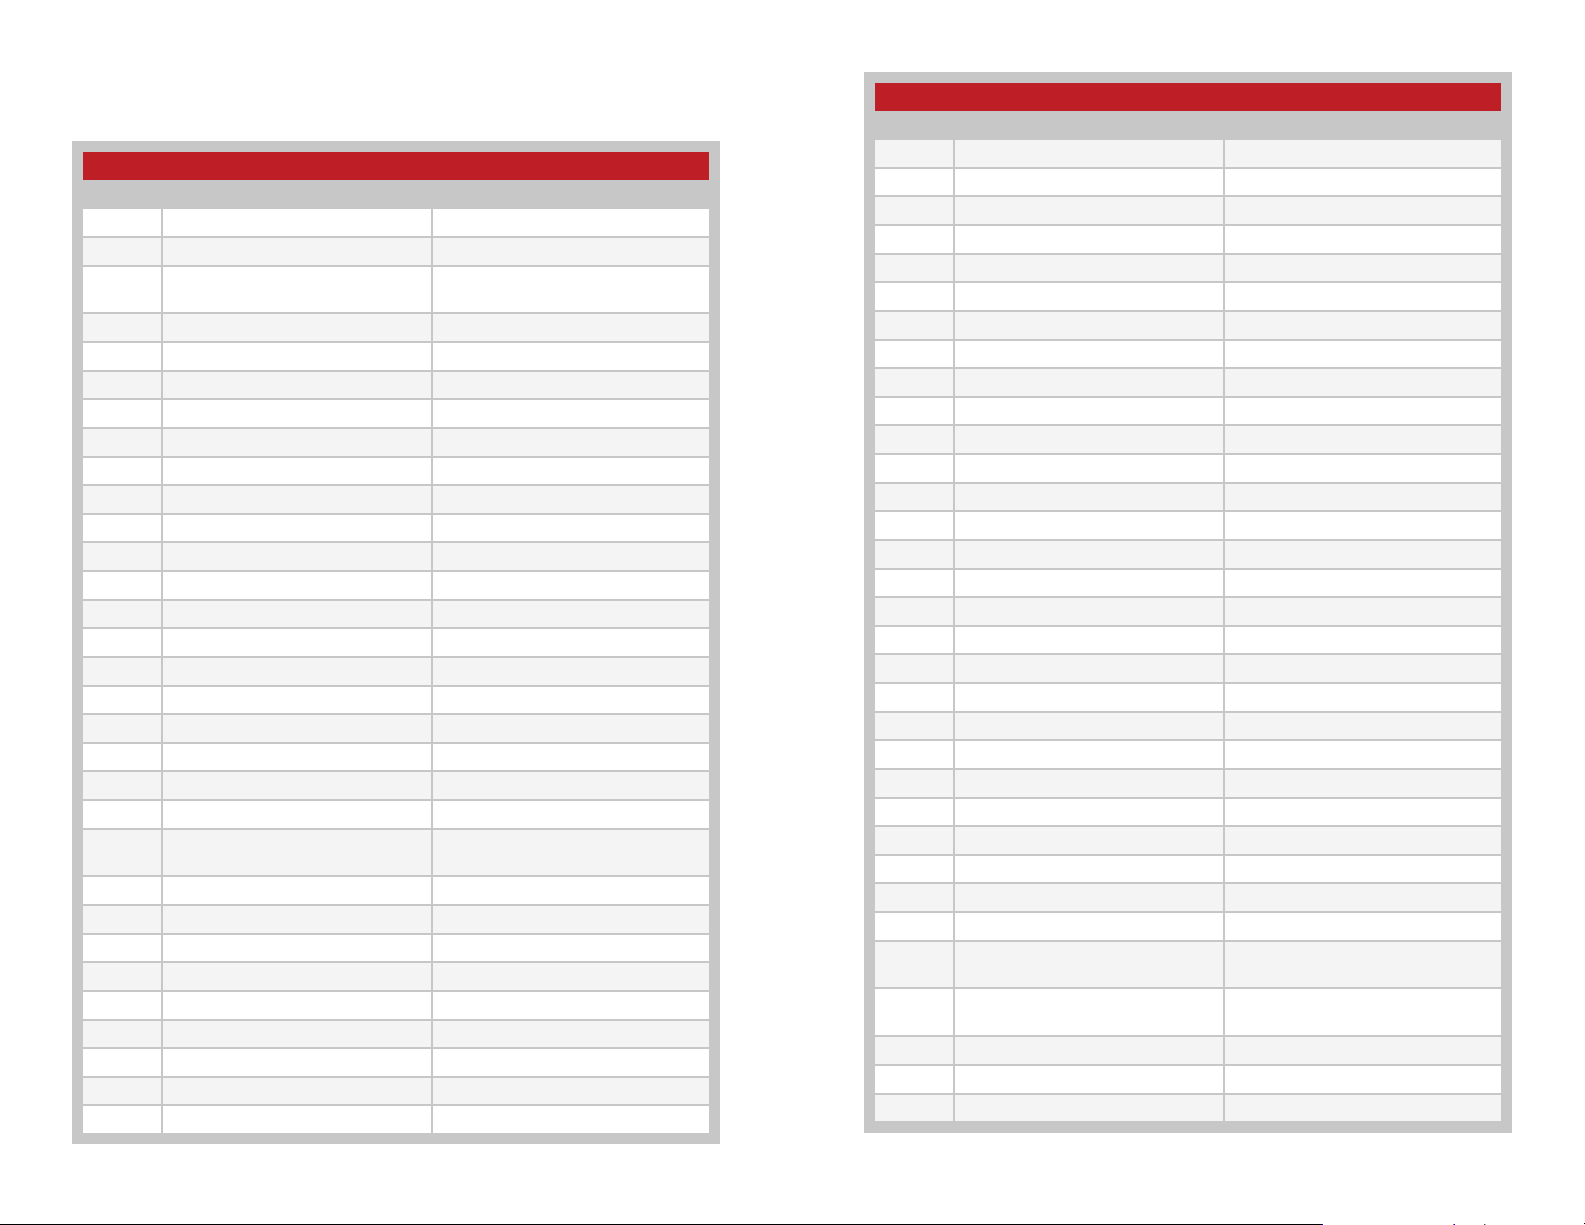
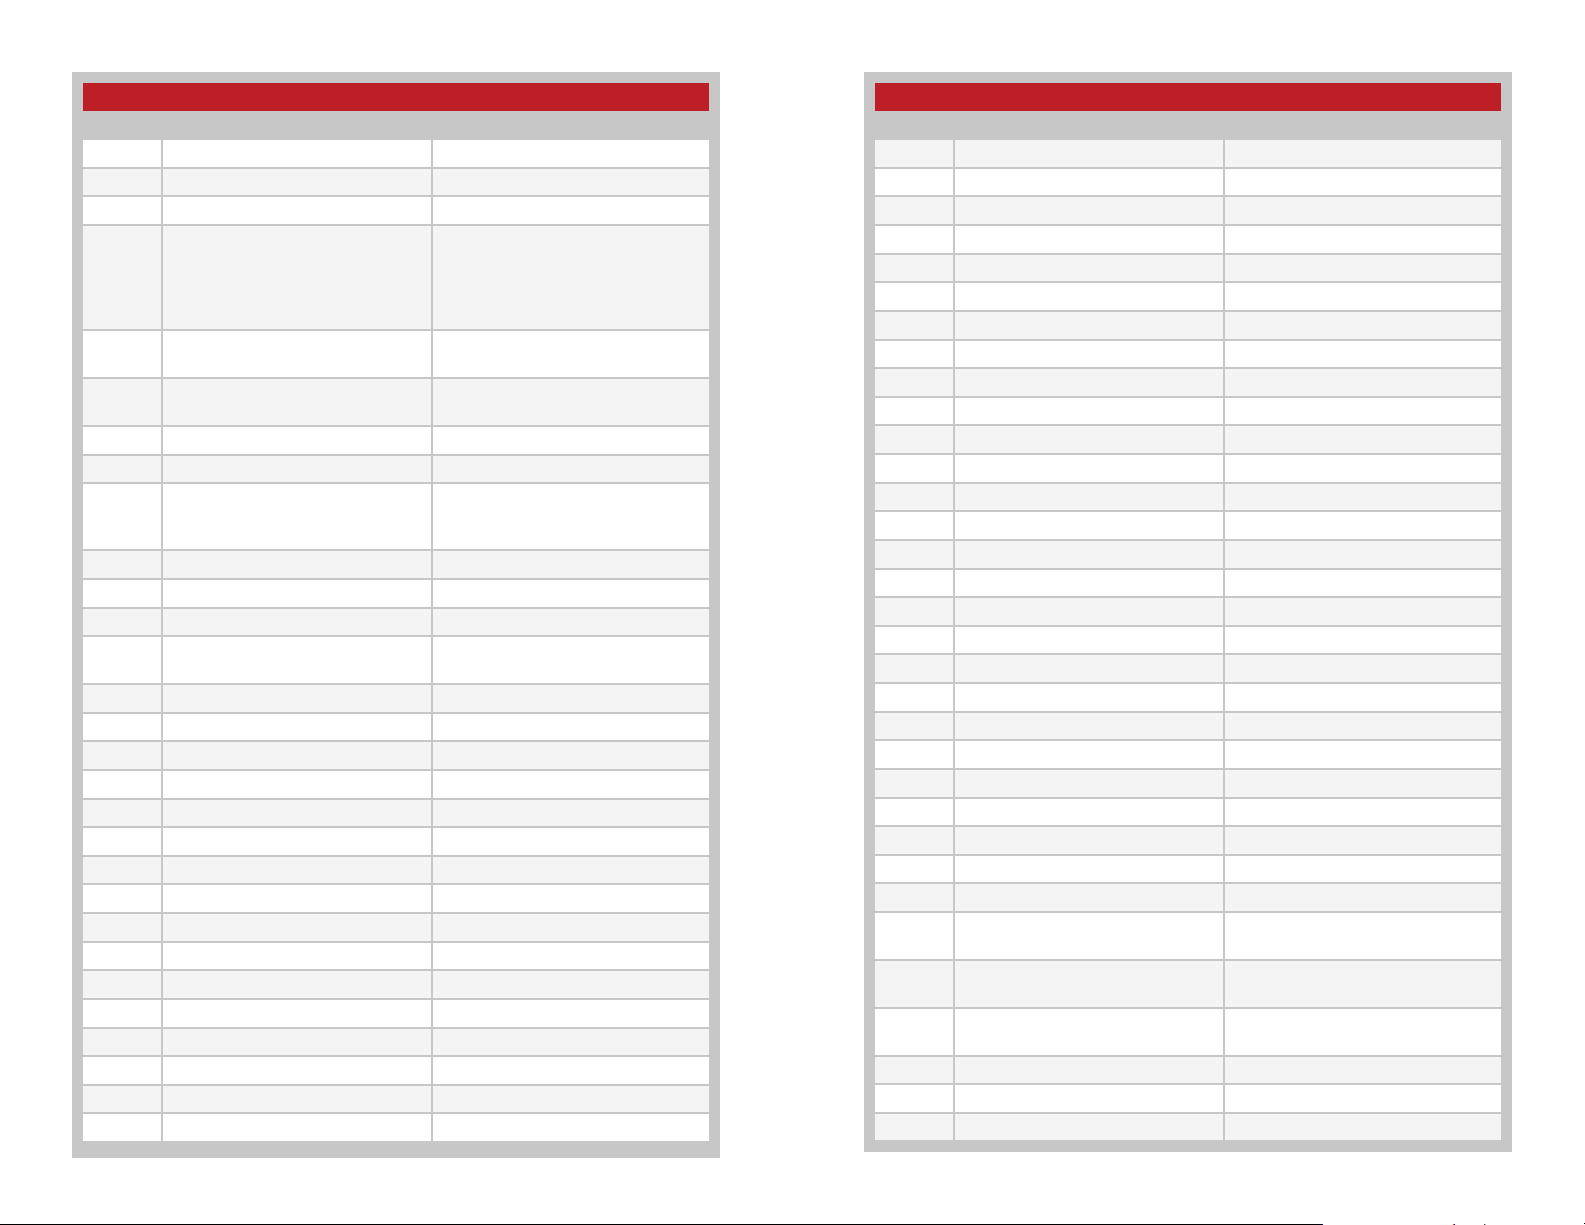
The following datums are supported by the FM Series.
FM Series GPS Receiver Supported Datums
Number Datum Region
0 WGS1984 International
1 Tokyo Japan
2 Tokyo
3 User Setting User Setting
4 Adindan Burkina Faso
5 Adindan Cameroon
6 Adindan Ethiopia
7 Adindan Mali
8 Adindan Mean for Ethiopia, Sudan
9 Adindan Senegal
10 Adindan Sudan
11 Afgooye Somalia
12 Ain El Abd1970 Bahrain
13 Ain El Abd1970 Saudi Arabia
14 American Samoa1962 American Samoa Islands
15 Anna 1 Astro1965 Cocos Island
16 Antigua Island Astro1943 Antigua(Leeward Islands)
17 Arc1950 Botswana
18 Arc1950 Burundi
19 Arc1950 Lesotho
20 Arc1950 Malawi
21 Arc1950
22 Arc1950 Swaziland
23 Arc1950 Zaire
24 Arc1950 Zambia
25 Arc1950 Zimbabwe
26 Arc1960 Mean For Kenya Tanzania
27 Arc1960 Kenya
28 Arc1960 Tanzania
29 Ascension Island1958 Ascension Island
30 Astro Beacon E 1945 Iwo Jima
Mean for Japan, South Korea,
Okinawa
Mean for Botswana, Lesotho, Malawi,
Swaziland, Zaire, Zambia, Zimbabwe
FM Series GPS Receiver Supported Datums
Number Datum Region
31 Astro Dos 71/4 St Helena Island
32 Astro Tern Island (FRIG) 1961 Tern Island
33 Astronomical Station 1952 Marcus Island
34 Australian Geodetic 1966 Australia, Tasmania
35 Australian Geodetic 1984 Australia, Tasmania
36 Ayabelle Lighthouse Djibouti
37 Bellevue (IGN) Efate and Erromango Islands
38 Bermuda 1957 Bermuda
39 Bissau Guuinea-Bissau
40 Bogota Observatory Colombia
41 Bukit Rimpah Indonesia (Bangka and Belitung Ids)
42 Camp Area Astro Antarctica (McMurdi Camp Area)
43 Campo Inchauspe Argentina
44 Canton Astro1966 Phoenix Island
45 Cape South Africa
46 Cape Canaveral Bahamas, Florida
47 Carthage Tunisia
48 Chatham Island Astro1971 New Zealand (Chatham Island)
49 Chua Astro Paraguay
50 Corrego Alegre Brazil
51 Dabola Guinea
52 Deception Island Deception Island, Antarctica
53 Djakarta (Batavia) Indonesia (Sumatra)
54 Dos 1968 New Georgia Islands (Gizo Island)
55 Easter Island 1967 Easter Island
56 Estonia Coordinate System1937 Estonia
57 European 1950 Cyprus
58 European 1950 Egypt
59 European 1950
60 European 1950
61 European 1950 Finland, Norway
62 European 1950 Greece
63 European 1950 Iran
England, Channel Islands, Scotland,
Shetland Islands
England, Ireland, Scotland, Shetland
Islands
– –
40 41
– –
Page 24
FM Series GPS Receiver Supported Datums
Number Datum Region
64 European 1950 Italy (Sardinia)
65 European 1950 Italy (Sicily)
66 European 1950 Malta
Mean For Austria, Belgium, Denmark,
67 European 1950
68 European 1950
69 European 1950
70 European 1950 Portugal, Spain
71 European 1950 Tunisia,
72 European 1979
73 Fort Thomas 1955 Nevis St Kitts (Leeward Islands)
74 Gan 1970 Republic Of Maldives
75 Geodetic Dataum 1970 New Zealand
76 Graciosa Base SW1948
77 Guam1963 Guam
78 Gunung Segara Indonesia (Kalimantan)
79 Gux l Astro Guadalcanal Island
80 Herat North Afghanistan
81 Hermannskogel Datum Croatia-Serbia, Bosnia-Herzegoivna
82 Hjorsey 1955 Iceland
83 Hongkong 1963 Hong Kong
84 Hu Tzu Shan Taiwan
85 Indian Bangladesh
86 Indian India, Nepal
87 Indian Pakistan
88 Indian 1954 Thailand
89 Indian 1960 Vietnam (Con Son Island)
90 Indian 1960 Vietnam (Near 16 deg N)
91 Indian 1975 Thailand
92 Indonesian 1974 Indonesian
Finland, France, W Germany,
Gibraltar, Greece, Italy, Luxembourg,
Netherlands, Norway, Portugal, Spain,
Sweden, Switzerland
Mean For Austria, Denmark, France,
W Germany, Netherland, Switzerland
Mean For Iraq, Israel, Jordan,
Lebanon, Kuwait, Saudi Arabia, Syria
Mean For Austria, Finland
,Netherlands ,Norway, Spain,
Sweden, Switzerland
Azores (Faial, Graciosa, Pico, Sao,
Jorge, Terceria)
FM Series GPS Receiver Supported Datums
Number Datum Region
93 Ireland 1965 Ireland
94 ISTS 061 Astro 1968 South Georgia Islands
95 ISTS 073 Astro 1969 Diego Garcia
96 Johnston Island 1961 Johnston Island
97 Kandawala Sri Lanka
98 Kerguelen Island 1949 Kerguelen Island
99 Kertau 1948 West Malaysia and Singapore
100 Kusaie Astro 1951 Caroline Islands
101 Korean Geodetic System South Korea
102 LC5 Astro 1961 Cayman Brac Island
103 Leigon Ghana
104 Liberia 1964 Liberia
105 Luzon Philippines (Excluding Mindanao)
106 Luzon Philippines (Mindanao)
107 M'Poraloko Gabon
108 Mahe 1971 Mahe Island
109 Massawa Ethiopia (Eritrea)
110 Merchich Morocco
111 Midway Astro 1961 Midway Islands
112 Minna Cameroon
113 Minna Nigeria
114 Montserrat Island Astro 1958 Montserrat (Leeward Island)
115 Nahrwan Oman (Masirah Island)
116 Nahrwan Saudi Arabia
117 Nahrwan United Arab Emirates
118 Naparima BWI Trinidad and Tobago
119 North American 1927 Alaska (Excluding Aleutian Ids)
120 North American 1927
121 North American 1927
122 North American 1927
123 North American 1927 Bahamas (San Salvador Islands)
124 North American 1927 Canada (Alberta, British Columbia)
125 North American 1927 Canada (Manitoba, Ontario)
Alaska (Aleutian Ids East of 180
degW)
Alaska (Aleutian Ids West of 180
degW)
Bahamas (Except San Salvador
Islands)
– –
42 43
– –
Page 25
FM Series GPS Receiver Supported Datums
Number Datum Region
126 North American 1927
127 North American 1927
128 North American 1927 Canada (Yukon)
129 North American 1927 Canal Zone
130 North American 1927 Cuba
131 North American 1927 Greenland (Hayes Peninsula)
132 North American 1927
133 North American 1927
134 North American 1927 Mean for Canada
135 North American 1927 Mean for Conus
136 North American 1927
137 North American 1927
138 North American 1927 Mexico
139 North American 1983 Alaska (Excluding Aleutian Ids)
140 North American 1983 Aleutian Ids
141 North American 1983 Canada
142 North American 1983 Conus
143 North American 1983 Hawaii
144 North American 1983 Mexico, Central America
145 North Sahara 1959 Algeria
146 Observatorio Meteorologico 1939 Azores (Corvo and Flores Islands)
147 Old Egyptian 1907 Egypt
148 Old Hawaiian Hawaii
149 Old Hawaiian Kauai
150 Old Hawaiian Maui
151 Old Hawaiian Mean for Hawaii, Kauai, Maui, Oahu
152 Old Hawaiian Oahu
153 Oman Oman
Canada (New Brunswick,
Newfoundland, Nova Scotia, Quebec)
Canada (Northwest Territories,
Saskatchewan)
Mean For Antigua, Barbados,
Barbuda, Caicos Islands, Cuba,
Dominican, Grand Cayman, Jamaica,
Turks Islands
Mean for Belize, Costa Rica, El
Salvador, Guatemala, Honduras,
Nicaragua
Mean for Conus (East of Mississippi,
River Including Louisiana, Missouri,
Minnesota)
Mean for Conus (West of Mississippi,
River Excluding Louisiana, Minnesota,
Missouri)
FM Series GPS Receiver Supported Datums
Number Datum Region
154 Ordnance Survey Great Britain 1936 England
155 Ordnance Survey Great Britain 1936 England, Isle of Man, Wales
156 Ordnance Survey Great Britain 1936
157 Ordnance Survey Great Britain 1936 Scotland, Shetland Islands
158 Ordnance Survey Great Britain 1936 Wales
159 Pico de las Nieves Canary Islands
160 Pitcairn Astro 1967 Pitcairn Island
161 Point 58 Mean for Burkina Faso and Niger
162 Pointe Noire 1948 Congo
163 Porto Santo 1936 Porto Santo, Madeira Islands
164 Provisional South American 1956 Bolivia
165 Provisional South American 1956 Chile (Northern Near 19 deg S)
166 Provisional South American 1956 Chile (Southern Near 43 deg S)
167 Provisional South American 1956 Colombia
168 Provisional South American 1956 Ecuador
169 Provisional South American 1956 Guyana
170 Provisional South American 1956
171 Provisional South American 1956 Peru
172 Provisional South American 1956 Venezuela
173 Provisional South Chilean 1963 Chile (Near 53 deg S) (Hito XVIII)
174 Puerto Rico Puerto Rico, Virgin Islands
175 Pulkovo 1942 Russia
176 Qatar National Qatar
177 Qornoq Greenland (South)
178 Reunion Mascarene Island
179 Rome 1940 Italy (Sardinia)
180 S-42 (Pulkovo 1942) Hungary
181 S-42 (Pulkovo 1942) Poland
182 S-42 (Pulkovo 1942) Czechoslavakia
183 S-42 (Pulkovo 1942) Lativa
184 S-42 (Pulkovo 1942) Kazakhstan
185 S-42 (Pulkovo 1942) Albania
186 S-42 (Pulkovo 1942) Romania
187 S-JTSK Czechoslavakia (Prior 1 Jan1993)
Mean For England, Isle of Man,
Scotland, Shetland Island, Wales
Mean for Bolivia Chile, Colombia,
Ecuador, Guyana, Peru, Venezuela
– –
44 45
– –
Page 26
FM Series GPS Receiver Supported Datums
Number Datum Region
188 Santo (Dos) 1965 Espirito Santo Island
189 Sao Braz Azores (Sao Miguel, Santa Maria Ids)
190 Sapper Hill 1943 East Falkland Island
191 Schwarzeck Namibia
192 Selvagem Grande 1938 Salvage Islands
193 Sierra Leone 1960 Sierra Leone
194 South American 1969 Argentina
195 South American 1969 Bolivia
196 South American 1969 Brazil
197 South American 1969 Chile
198 South American 1969 Colombia
199 South American 1969 Ecuador
200 South American 1969 Ecuador (Baltra, Galapagos)
201 South American 1969 Guyana
Mean For Argentina, Bolivia, Brazil,
202 South American 1969
203 South American 1969 Paraguay
204 South American 1969 Peru
205 South American 1969 Trinidad and Tobago
206 South American 1969 Venezuela
207 South Asia Singapore
208 Tananarive Observatory 1925 Madagascar
209 Timbalai 1948 Brunei, E Malaysia (Sabah Sarawak)
210 Tokyo Japan
211 Tokyo
212 Tokyo Okinawa
213 Tokyo South Korea
214 Tristan Astro 1968 Tristam Da Cunha
215 Viti Levu 1916 Fiji (Viti Levu Island)
216 Voirol 1960 Algeria
217 Wake Island Astro 1952 Wake Atoll
218 Wake-Eniwetok 1960 Marshall Islands
219 WGS 1972 Global Definition
Chile, Colombia, Ecuador, Guyana,
Paraguay, Peru, Trinidad and Tobago,
Venezuela
Mean for Japan, South Korea,
Okinawa
FM Series GPS Receiver Supported Datums
Number Datum Region
220 WGS 1984 Global Definition
221 Yacare Uruguay
222 Zanderij Suriname
Figure 45: Supported Datums
– –
46 47
– –
Page 27
Linx Technologies
159 Ort Lane
Merlin, OR, US 97532
Phone: +1 541 471 6256
Fax: +1 541 471 6251
www.linxtechnologies.com
Disclaimer
Linx Technologies is continually striving to improve the quality and function of its products. For this reason, we
reserve the right to make changes to our products without notice. The information contained in this Data Guide
is believed to be accurate as of the time of publication. Specifications are based on representative lot samples.
Values may vary from lot-to-lot and are not guaranteed. “Typical” parameters can and do vary over lots and
application. Linx Technologies makes no guarantee, warranty, or representation regarding the suitability of any
product for use in any specific application. It is the customer’s responsibility to verify the suitability of the part for
the intended application. NO LINX PRODUCT IS INTENDED FOR USE IN ANY APPLICATION WHERE THE SAFETY
OF LIFE OR PROPERTY IS AT RISK.
Linx Technologies DISCLAIMS ALL WARRANTIES OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR
PURPOSE. IN NO EVENT SHALL LINX TECHNOLOGIES BE LIABLE FOR ANY OF CUSTOMER’S INCIDENTAL OR
CONSEQUENTIAL DAMAGES ARISING IN ANY WAY FROM ANY DEFECTIVE OR NON-CONFORMING PRODUCTS
OR FOR ANY OTHER BREACH OF CONTRACT BY LINX TECHNOLOGIES. The limitations on Linx Technologies’
liability are applicable to any and all claims or theories of recovery asserted by Customer, including, without
limitation, breach of contract, breach of warranty, strict liability, or negligence. Customer assumes all liability
(including, without limitation, liability for injury to person or property, economic loss, or business interruption) for
all claims, including claims from third parties, arising from the use of the Products. The Customer will indemnify,
defend, protect, and hold harmless Linx Technologies and its officers, employees, subsidiaries, affiliates,
distributors, and representatives from and against all claims, damages, actions, suits, proceedings, demands,
assessments, adjustments, costs, and expenses incurred by Linx Technologies as a result of or arising from any
Products sold by Linx Technologies to Customer. Under no conditions will Linx Technologies be responsible for
losses arising from the use or failure of the device in any application, other than the repair, replacement, or refund
limited to the original product purchase price. Devices described in this publication may contain proprietary,
patented, or copyrighted techniques, components, or materials. Under no circumstances shall any user be
conveyed any license or right to the use or ownership of such items.
©2015 Linx Technologies. All rights reserved.
The stylized Linx logo, Wireless Made Simple, WiSE, CipherLinx and the stylized CL logo are trademarks of Linx Technologies.
 Loading...