

Page 1
HumPRCTM Series
Master Development System
User's Guide
Page 2
Warning: Some customers may want Linx radio frequency (“RF”)
!
products to control machinery or devices remotely, including machinery
or devices that can cause death, bodily injuries, and/or property
damage if improperly or inadvertently triggered, particularly in industrial
settings or other applications implicating life-safety concerns (“Life and
Property Safety Situations”).
NO OEM LINX REMOTE CONTROL OR FUNCTION MODULE
SHOULD EVER BE USED IN LIFE AND PROPERTY SAFETY
SITUATIONS. No OEM Linx Remote Control or Function Module
should be modified for Life and Property Safety Situations. Such
modification cannot provide sufficient safety and will void the product’s
regulatory certification and warranty.
Table of Contents
1 Introduction
2 Ordering Information
3 HumPRC
3 HumPRC
3 HumPRC
Assignments
4 Programming Dock
4 Programming Dock Objects
TM
Series Transceiver Carrier Board
TM
Series Transceiver Carrier Board Objects
TM
Series Transceiver Carrier Board Pin
Customers may use our (non-Function) Modules, Antenna and
Connectors as part of other systems in Life Safety Situations, but
only with necessary and industry appropriate redundancies and
in compliance with applicable safety standards, including without
limitation, ANSI and NFPA standards. It is solely the responsibility
of any Linx customer who uses one or more of these products to
incorporate appropriate redundancies and safety standards for the Life
and Property Safety Situation application.
Do not use this or any Linx product to trigger an action directly
from the data line or RSSI lines without a protocol or encoder/
decoder to validate the data. Without validation, any signal from
another unrelated transmitter in the environment received by the module
could inadvertently trigger the action.
All RF products are susceptible to RF interference that can prevent
communication. RF products without frequency agility or hopping
implemented are more subject to interference. This module does have
a frequency hopping protocol built in, but the developer should still be
aware of the risk of interference.
Do not use any Linx product over the limits in this data guide.
Excessive voltage or extended operation at the maximum voltage could
cause product failure. Exceeding the reflow temperature profile could
cause product failure which is not immediately evident.
Do not make any physical or electrical modifications to any Linx
product. This will void the warranty and regulatory and UL certifications
and may cause product failure which is not immediately evident.
5 Remote Control Demo Board
5 Remote Control Demo Board Objects
6 Prototype Board
6 Prototype Board Objects
7 HumPRC
TM
Series Handheld Transmitter Evaluation
Board
8 Long-range Handheld Transmitter Button
Assignments
8 Initial Setup
10 Using the Programming Dock
11 Using the Remote Control Demo Board
13 Using the Prototype Board
16 Using the Handheld Transmitter Evaluation Board
17 Joining a Transmitter
18 The Development Kit Demonstration Software
25 Development Kit Demonstration Software Example
31 Carrier Board Schematic
32 Remote Control Demo Board Schematic
36 Programming Dock Board Schematic
40 Prototype Board Schematic
43 HumPRC
TM
Series Evaluation Board Schematic
Page 3
HumPRCTM Master Development System
User's Guide
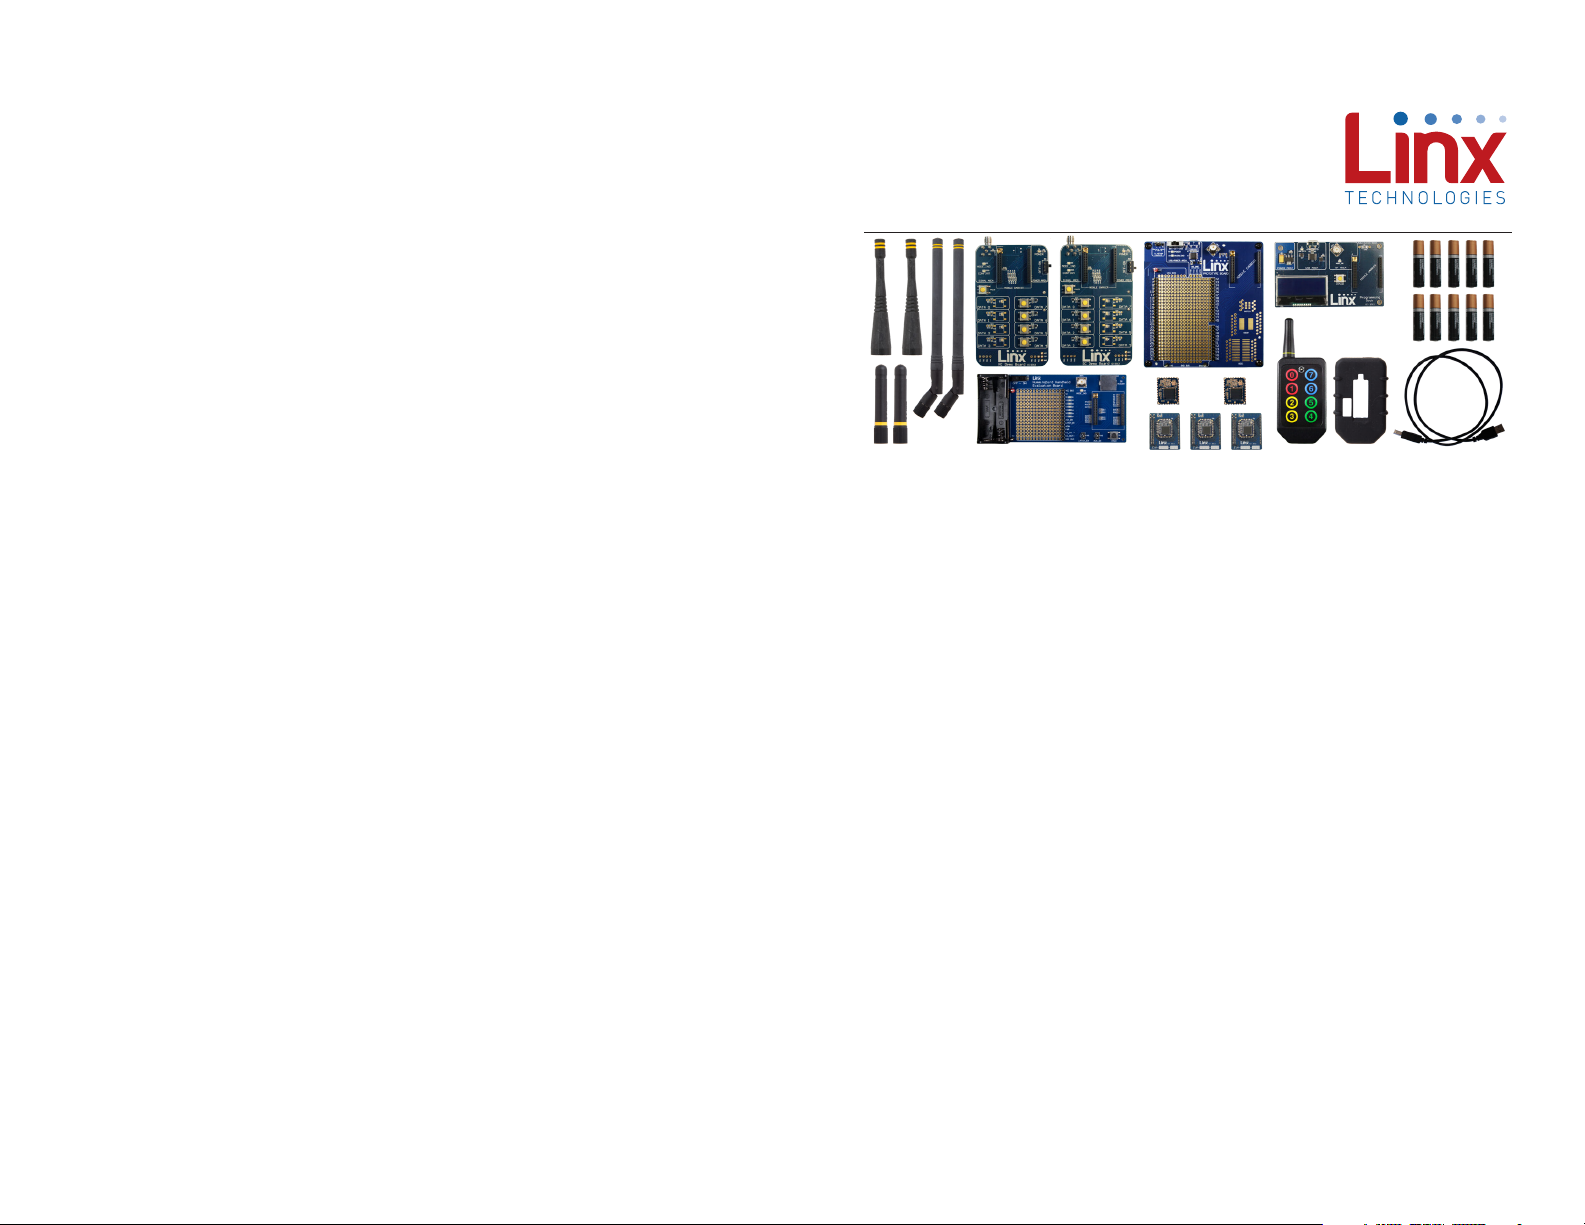
Figure 1: HumPRCTM Series Master Development System
Introduction
The Linx HumPRCTM Series Remote Control Transceiver modules offer
a simple, efficient and cost-effective method of adding remote control
capabilities to any product. The Master Development System provides a
designer with all the tools necessary to correctly and legally incorporate the
module into an end product. The boards serve several important functions:
• Rapid Module Evaluation: The boards allow the performance of the
Linx HumPRC™ Series modules to be evaluated quickly in a user’s
environment. The development boards can be used to evaluate the
range performance of the modules.
• Application Development: A prototyping board allows the development
of custom circuits directly on the board. All signal lines are available on
headers for easy access.
• Software Development: A programming dock with a PC interface allows
development and testing of custom software applications for control of
the module.
• Design Benchmark: The boards provide a known benchmark against
which the performance of a custom design may be judged.
Includes 3 Carrier Boards, 2 PRC Demo Boards, 1 Programming Dock, 1
Prototype Board, 2 HumPRC™ Series transceivers, 1 PRC Long-Range
Handheld transmitter and accessories, 1 evaluation board, antennas,
batteries, USB cables, software and full documentation.
– –
1
Revised 9/18/2017
Page 4
HumPRCTM Series Transceiver Carrier BoardOrdering Information
Ordering Information
Part Number Description
MDEV-***-PRC HumPRCTM Series Master Development System
HUM-***-PRC
HUM-***-PRC-CAS
HUM-***-PRC-UFL
EVM-***-PRC
EVM-***-PRC-CAS
EVM-***-PRC-UFL
HumPRCTM Series Remote Control Transceiver, Castellation
Interface, External Antenna Connection
HumPRCTM Series Remote Control Transceiver, Certified,
Castellation Interface, External Antenna Connection
HumPRCTM Series Remote Control Transceiver, Certified,
Castellation Interface, U.FL Connector
HumPRCTM Series Carrier Board, Not Certified, Through-Hole
Pin Interface, MMCX Connector for the Development System
HumPRCTM Series Carrier Board, Certified, Through-Hole Pin
Interface, RP-SMA Connector
HumPRCTM Series Carrier Board, Certified, Through-Hole Pin
Interface, U.FL Connector
MDEV-DEMO-RC-A Development System Remote Control Demo Board, Type A
MDEV-DEMO-RC-B Development System Remote Control Demo Board, Type B
MDEV-PGDOCK Development System Programming Dock
MDEV-PROTO Development System Prototype Board
CON-SOC-EVM EVM Module Socket Kit
*** = Frequency; 868, 900MHz
Figure 2: Ordering Information
2
3
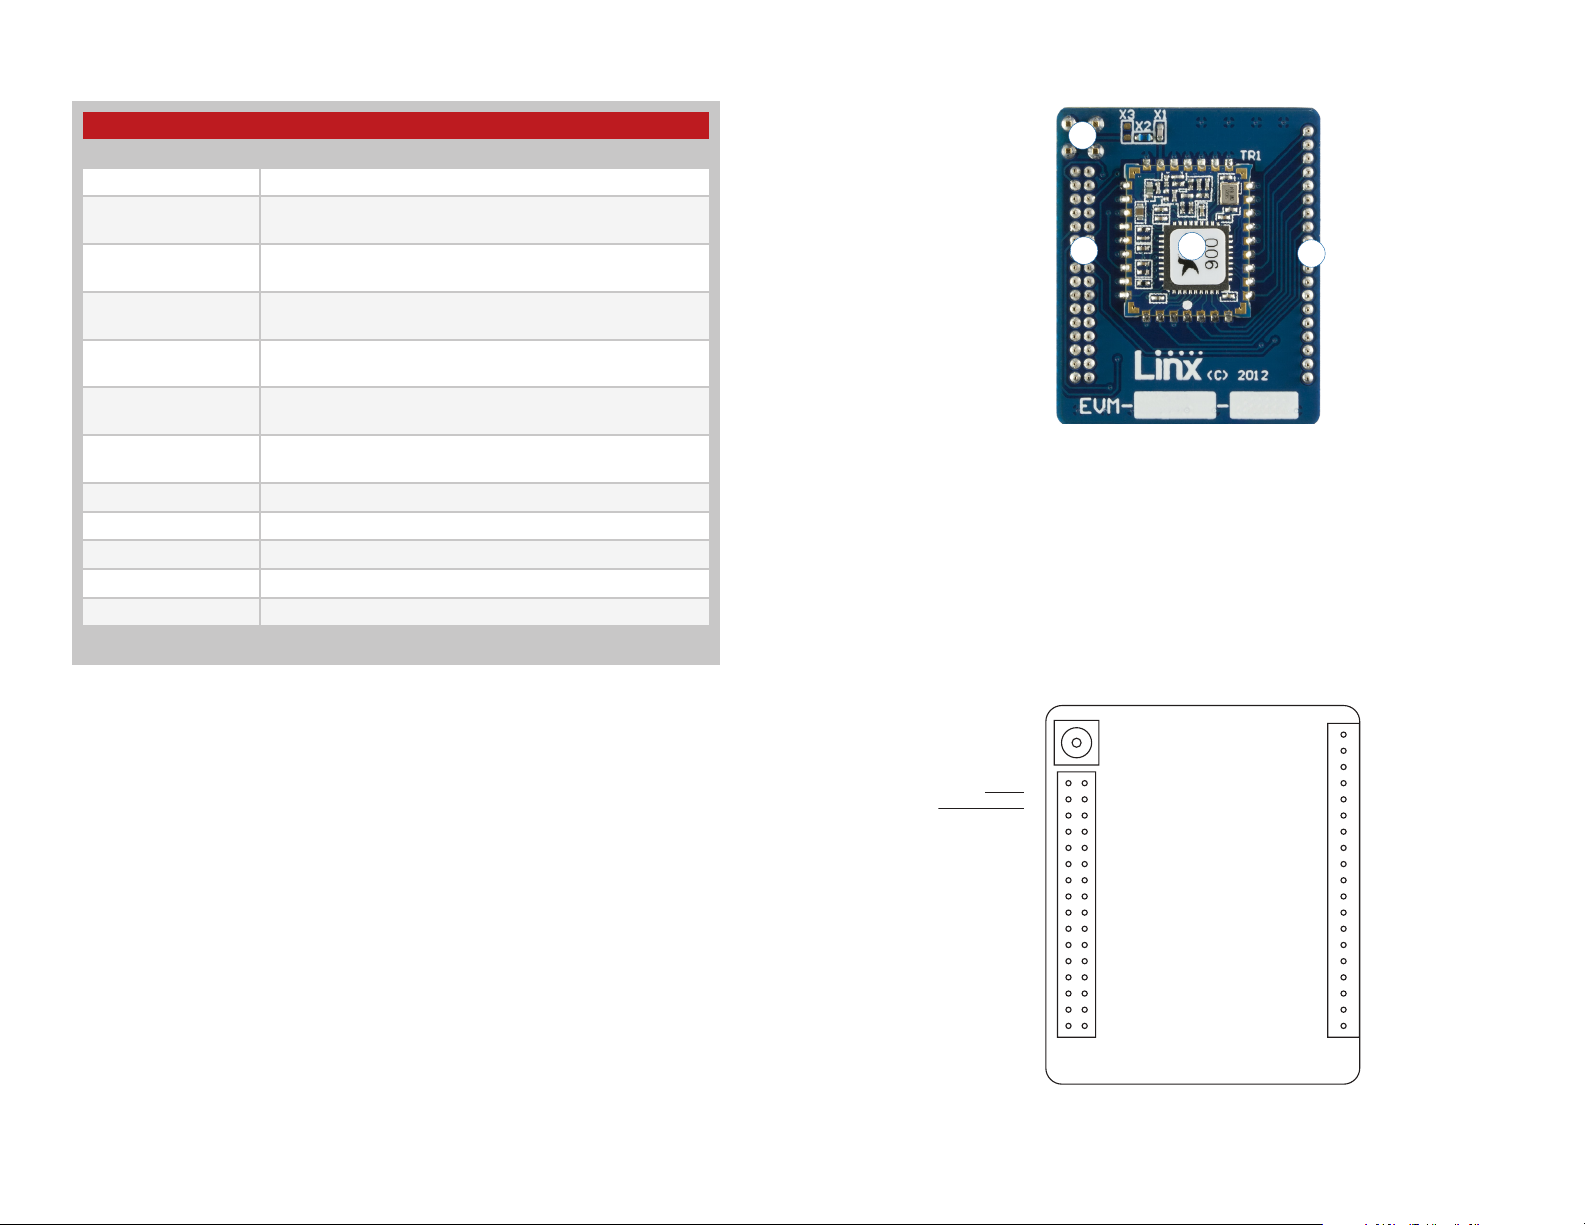
Figure 3: HumPRCTM Series Transceiver Carrier Board
1
4
HumPRCTM Series Transceiver Carrier Board Objects
1. HumPRCTM Series Transceiver
2. MMCX RF Connector
3. Dual Row Header
4. Single Row Header
HumPRCTM Series Transceiver Carrier Board Pin Assignments
ANTENNA 1 2-5 GND (RF Connector)
GND 6
RESET 8
POWER_DOWN 10
NC 12
PAIR 14
LNA_EN 16
NC 18
PA_EN 20
NC 22
NC 24
NC 26
NC 28
NC 30
NC 32
NC 34
NC 36
7 MODE_IND
9 CMD_DATA_IN
11 LATCH_EN
13 ACK_EN
15 CMD_DATA_OUT
17 VCC
19 C0
21 C1
23 NC
25 NC
27 NC
29 NC
31 NC
33 NC
35 NC
37 NC
Figure 4: HumPRCTM Series Transceiver Carrier Board Pin Assignments (Top View)
– –
2 3
38 S0
39 S1
40 S2
41 S3
42 S4
43 S5
44 S6
45 S7
46 ACK_OUT
47 NC
48 NC
49 NC
50 NC
51 NC
52 NC
53 NC
54 NC
55 NC
56 NC
– –
Page 5
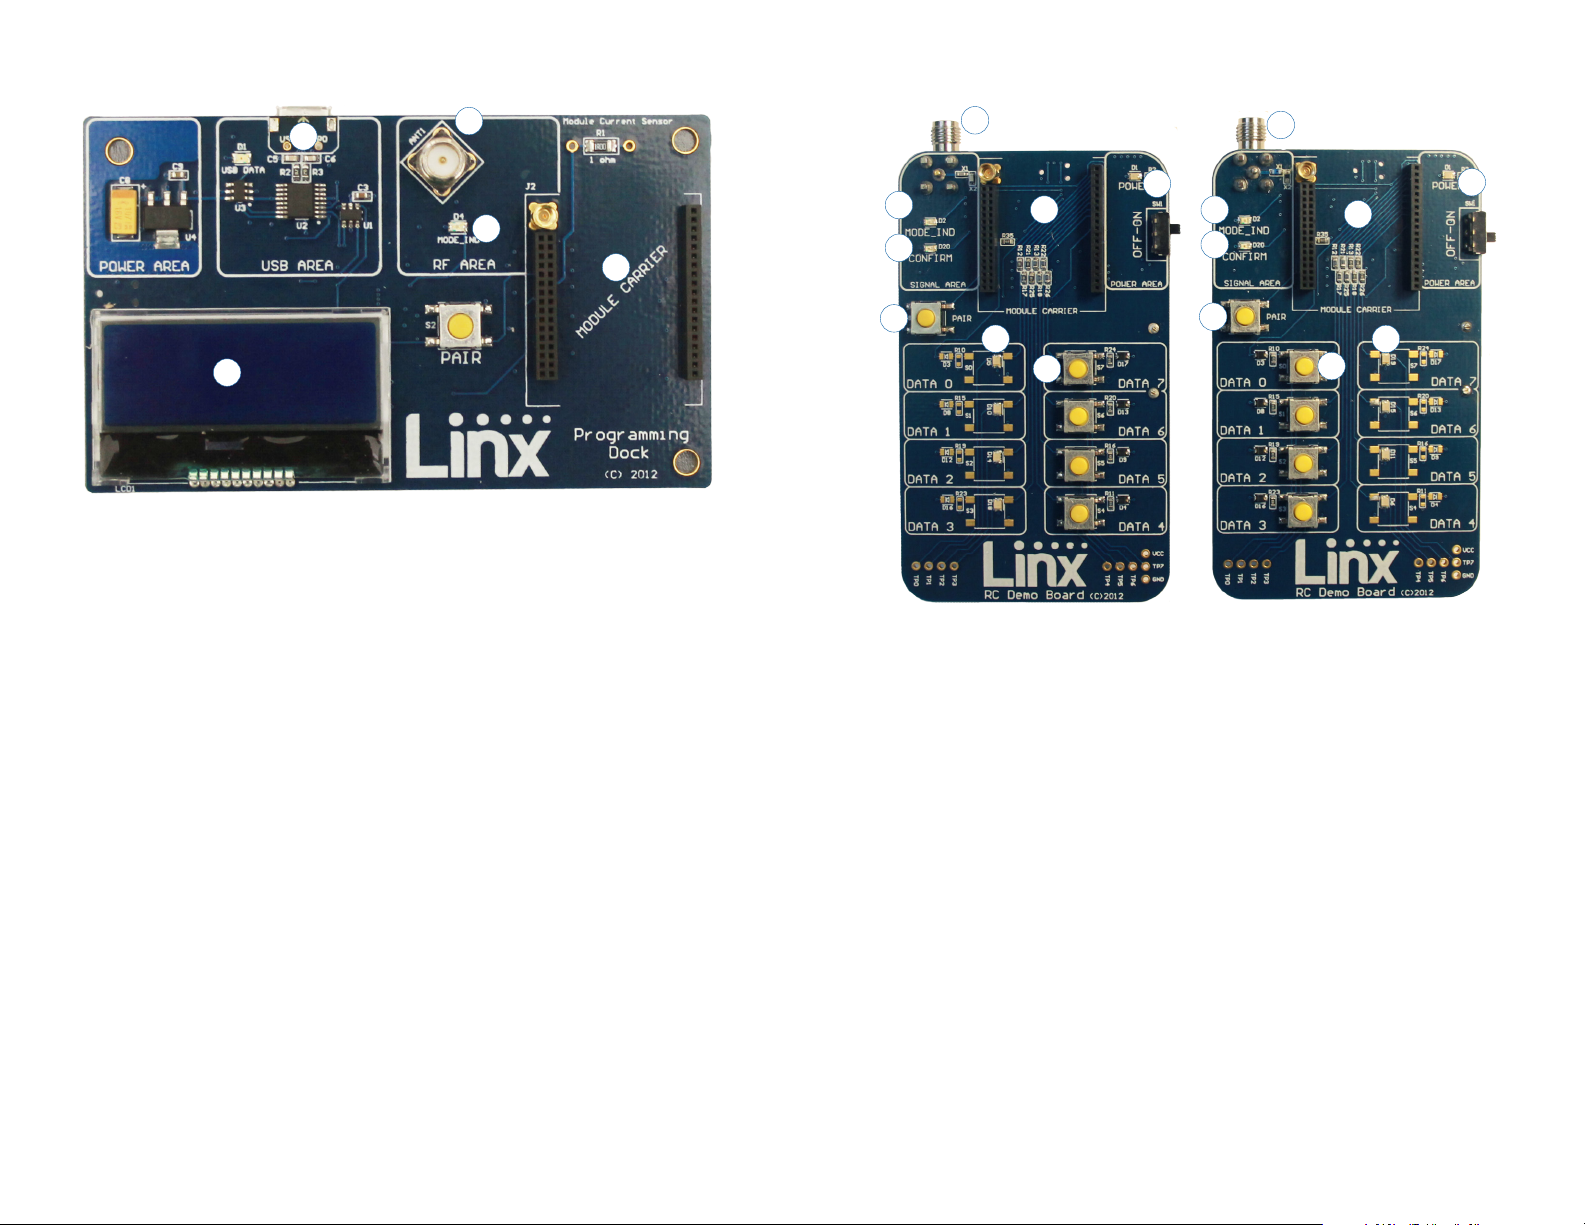
Programming Dock
Remote Control Demo Board
4
5
Figure 5: Programming Dock
Programming Dock Objects
1. Carrier Board Socket
2. RP-SMA Antenna Connector
3. MODE_IND LED
4. Micro USB Connector
5. LCD Display
2
4
3
5
1
6
2
3
1
7
8
4
5
6
2
3
1
1
7
8
Board BBoard A
Figure 6: Remote Control Demo Board
Remote Control Demo Board Objects
1. Carrier Board Socket
2. RP-SMA Antenna Connector
3. Power Switch
4. MODE_IND LED
5. CONFIRM LED
6. PAIR button
7. Status Line Output LEDs
8. Status Line Input Buttons
9. 4 AAA Batteries (Not shown, on the back of the boards)
– –
4 5
– –
Page 6
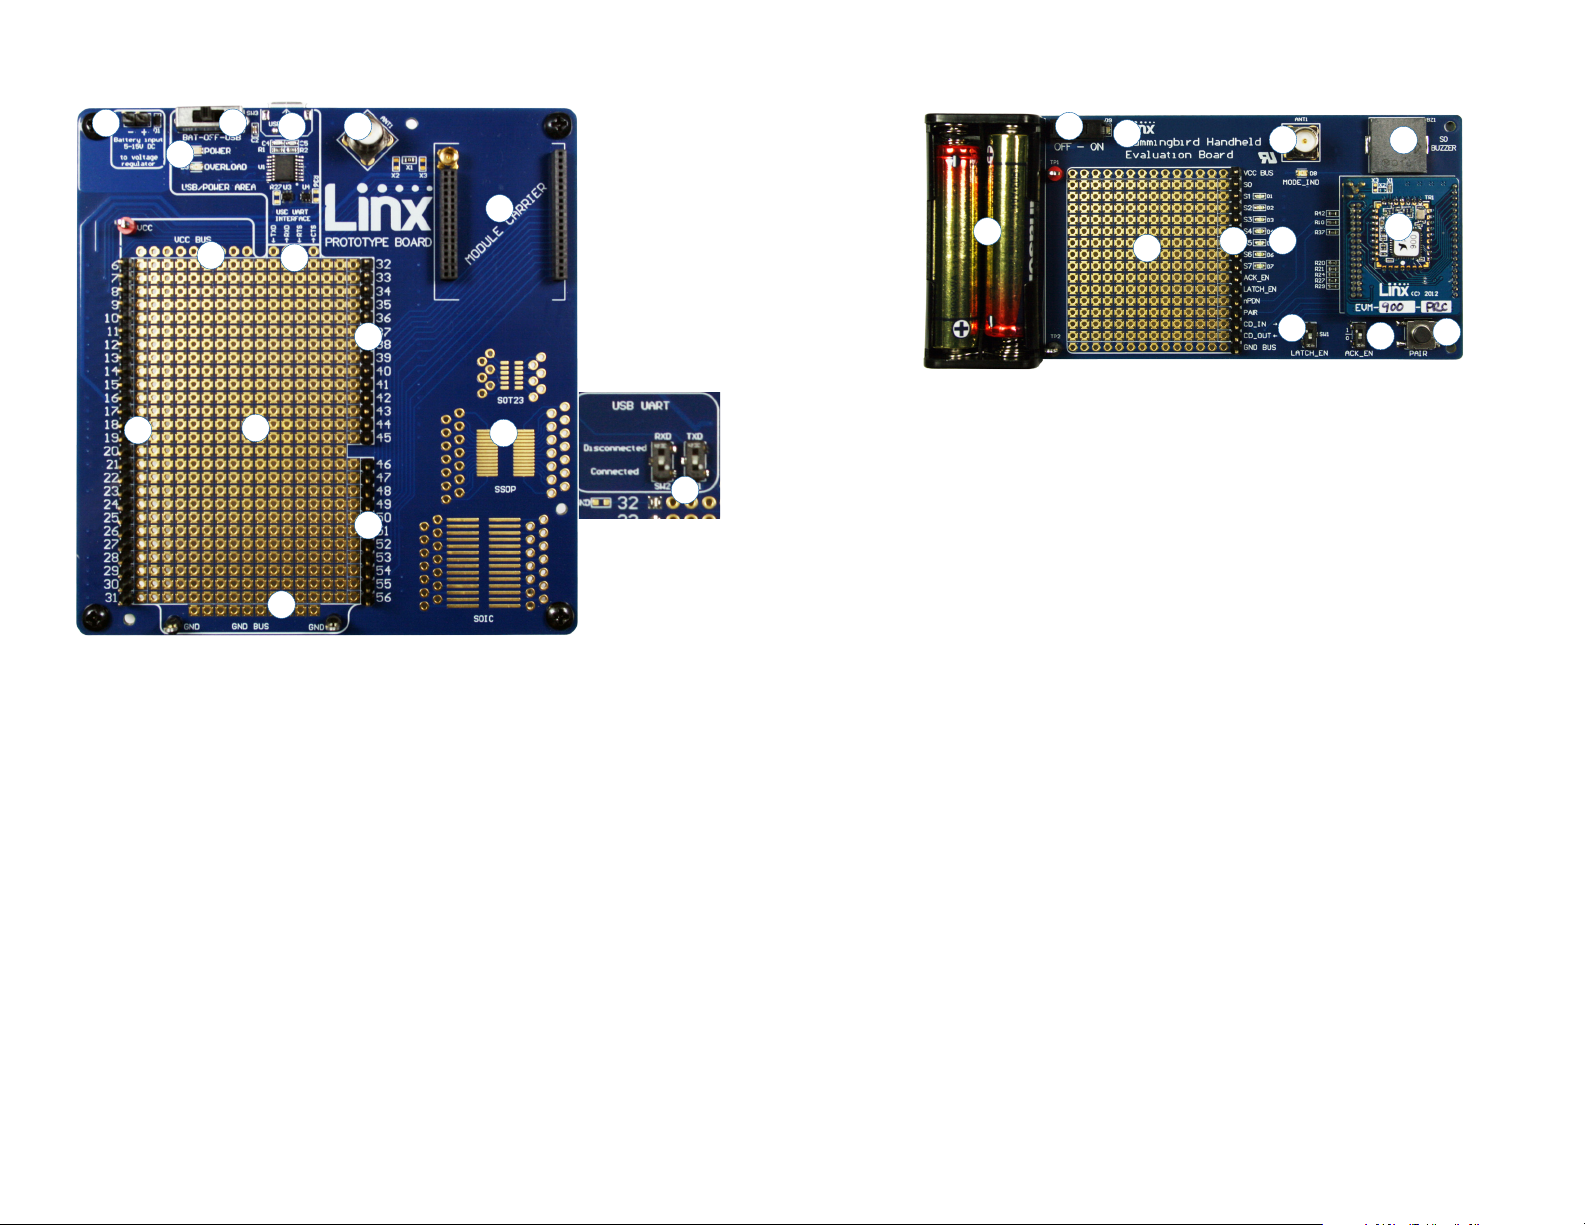
Prototype Board
HumPRCTM Series Handheld Transmitter Evaluation Board
6
11
Figure 7: Prototype Board
4
3
5
8
10
7
9
2
1
11
12
11
Prototype Board Objects
1. Carrier Board Socket
2. RP-SMA Antenna Connector
3. Micro USB Connector
4. Power Switch
5. Power LED
6. External Battery Connection
7. Prototyping Area
8. 3.3V Supply Bus
9. Ground Bus
10. USB Interface Lines
11. Module Interface Headers
12. Standard IC Package Footprints
13. Command Data Interface Routing Switches (on back)
13
2
3
1
4
Figure 8: HumPRCTM Series Transceiver Evaluation Board
5
1. Battery – 3VDC (use 2 AAA style batteries)
2. Power Switch
3. Power On Indicator LED
4. Prototyping Area
5. Breakout Header
6. HumPRCTM Series Transceiver Carrier Board
7. Reverse-Polarity SMA Antenna Connector
8. LEDs – S1–S7
9. Buzzer – S0
10. Latch Enable Selection Switch
11. ACK Enable Selection Switch
12. PAIR Button
7
8
10
11
9
6
12
– –
6 7
– –
Page 7
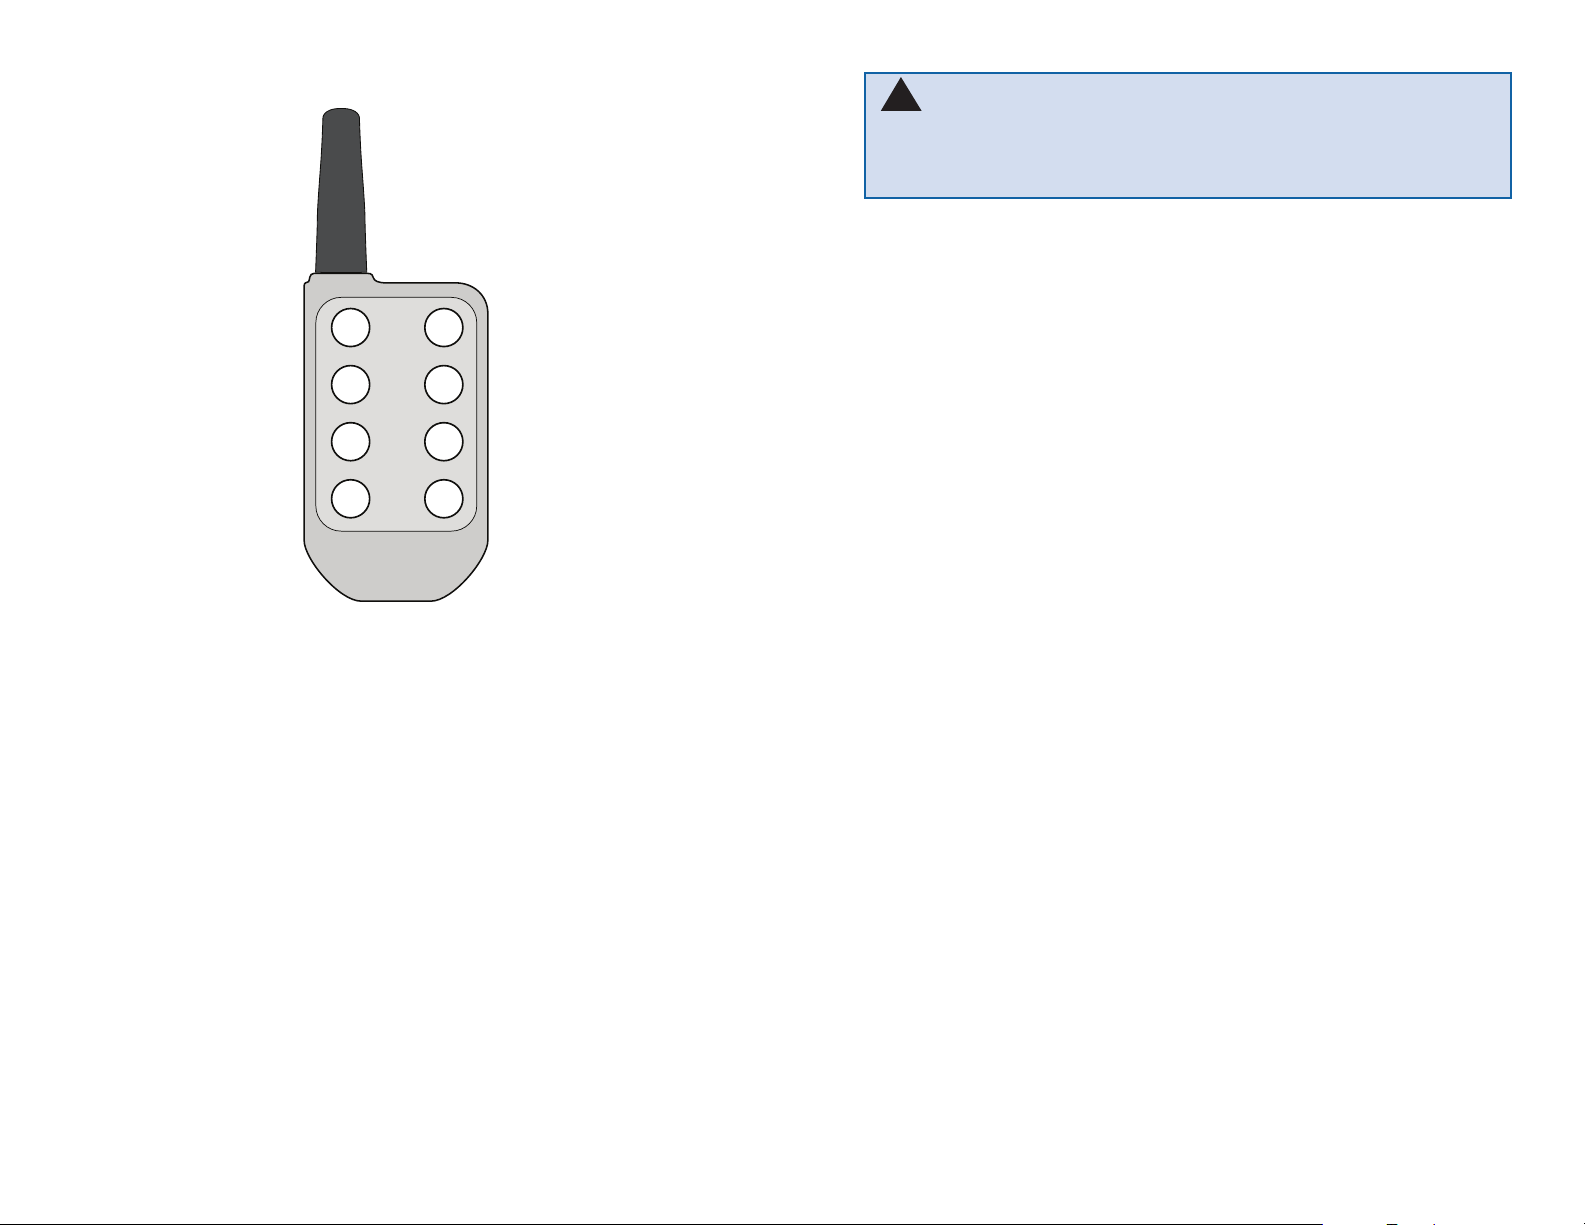
Long-range Handheld Transmitter Button Assignments
S0 S7
S1 S6
S2 S5
S3 S4
Figure 9: OTX-***-HH-LR8-PRC Button Assignments
Warning: Installing or removing a Carrier Board while power is
!
applied could cause permanent damage to the module. Either turn
off power to the board or unplug the USB cable before installing or
removing a Carrier Board
There are two Remote Control Demo Boards that are populated differently.
Board A has the buttons on the right column and board B has them on the
left column. These accept the Carrier Boards and are used to demonstrate
the bi-directional remote control functionality of the HumPRCTM Series.
They can also be used for range testing. These boards use hardware
configuration, so if any changes have been made to the modules using
the software then they may not operate correctly. A restore to default
configuration can be used to reset the modules.
The Programming Dock that has a socket for a Carrier Board and a USB
interface for connection to a PC. This is used with the demonstration
software included with the kit to configure the module through its
Command Data Interface.
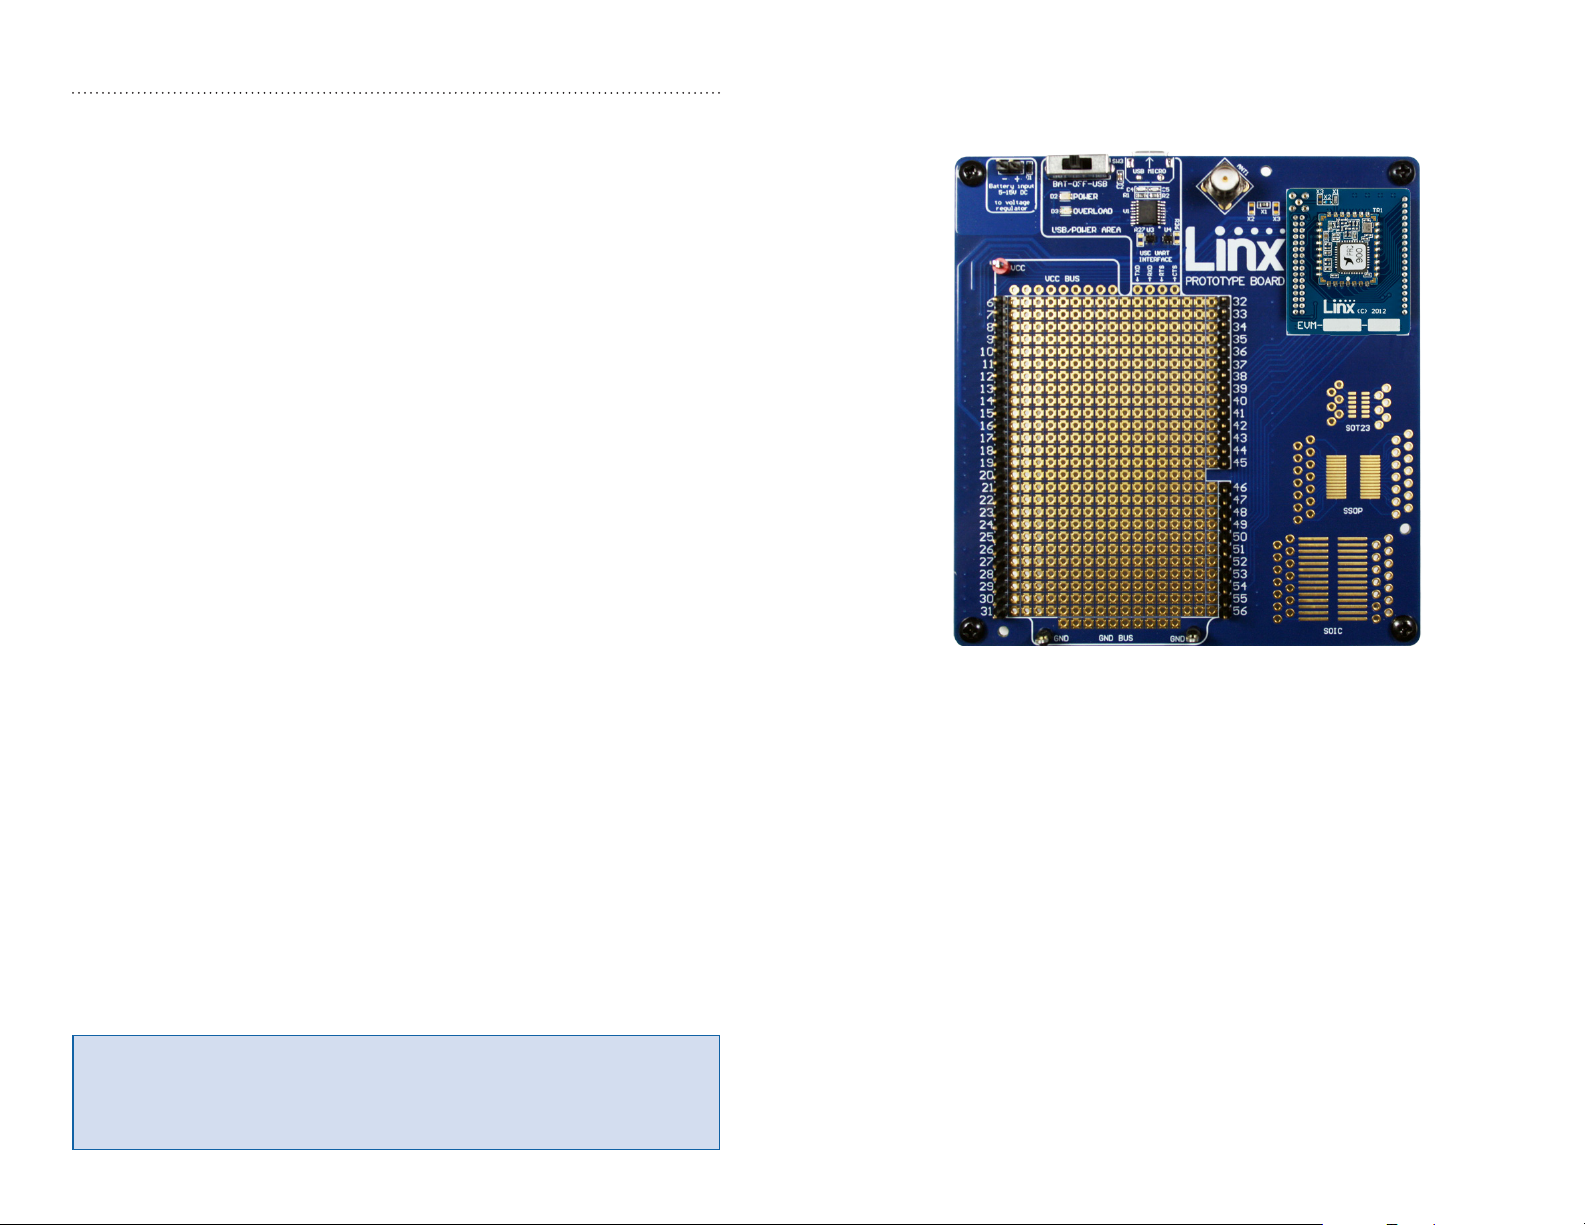
There is one Prototype Board that has a socket for a Carrier Board, a USB
interface and a large area of plated through holes that can be used to
develop custom circuitry. The board can be powered either from the USB
connection or an external battery.
Initial Setup
Several boards are included with the Development System that are
intended for different use cases:
1. Two Remote Control Demo Boards for bi-directional operation and
range testing
2. One Programming Dock to demonstrate use of the Command Data
Interface with a PC.
3. One Prototype Board for use in developing a custom application
4. One Handheld transmitter and Handheld Transmitter Evalution Board
for one-way operation with a finished transmitter.
The Carrier Boards have a HumPRCTM Series transceiver on a daughter
board with headers. These boards snap into sockets on the other boards,
enabling the modules to be easily moved among the test boards.
– –
8 9
There is one Handheld Transmitter Evaluation Board that is used to receive
transmissions from the included Long-Range Handheld Transmitter. This
board has a buzzer and LEDs that are activated by the transmitter. This can
be used for simple range testing.
The development software supports Windows 7 and 10; with Java 1.6 or
later.
– –
Page 8
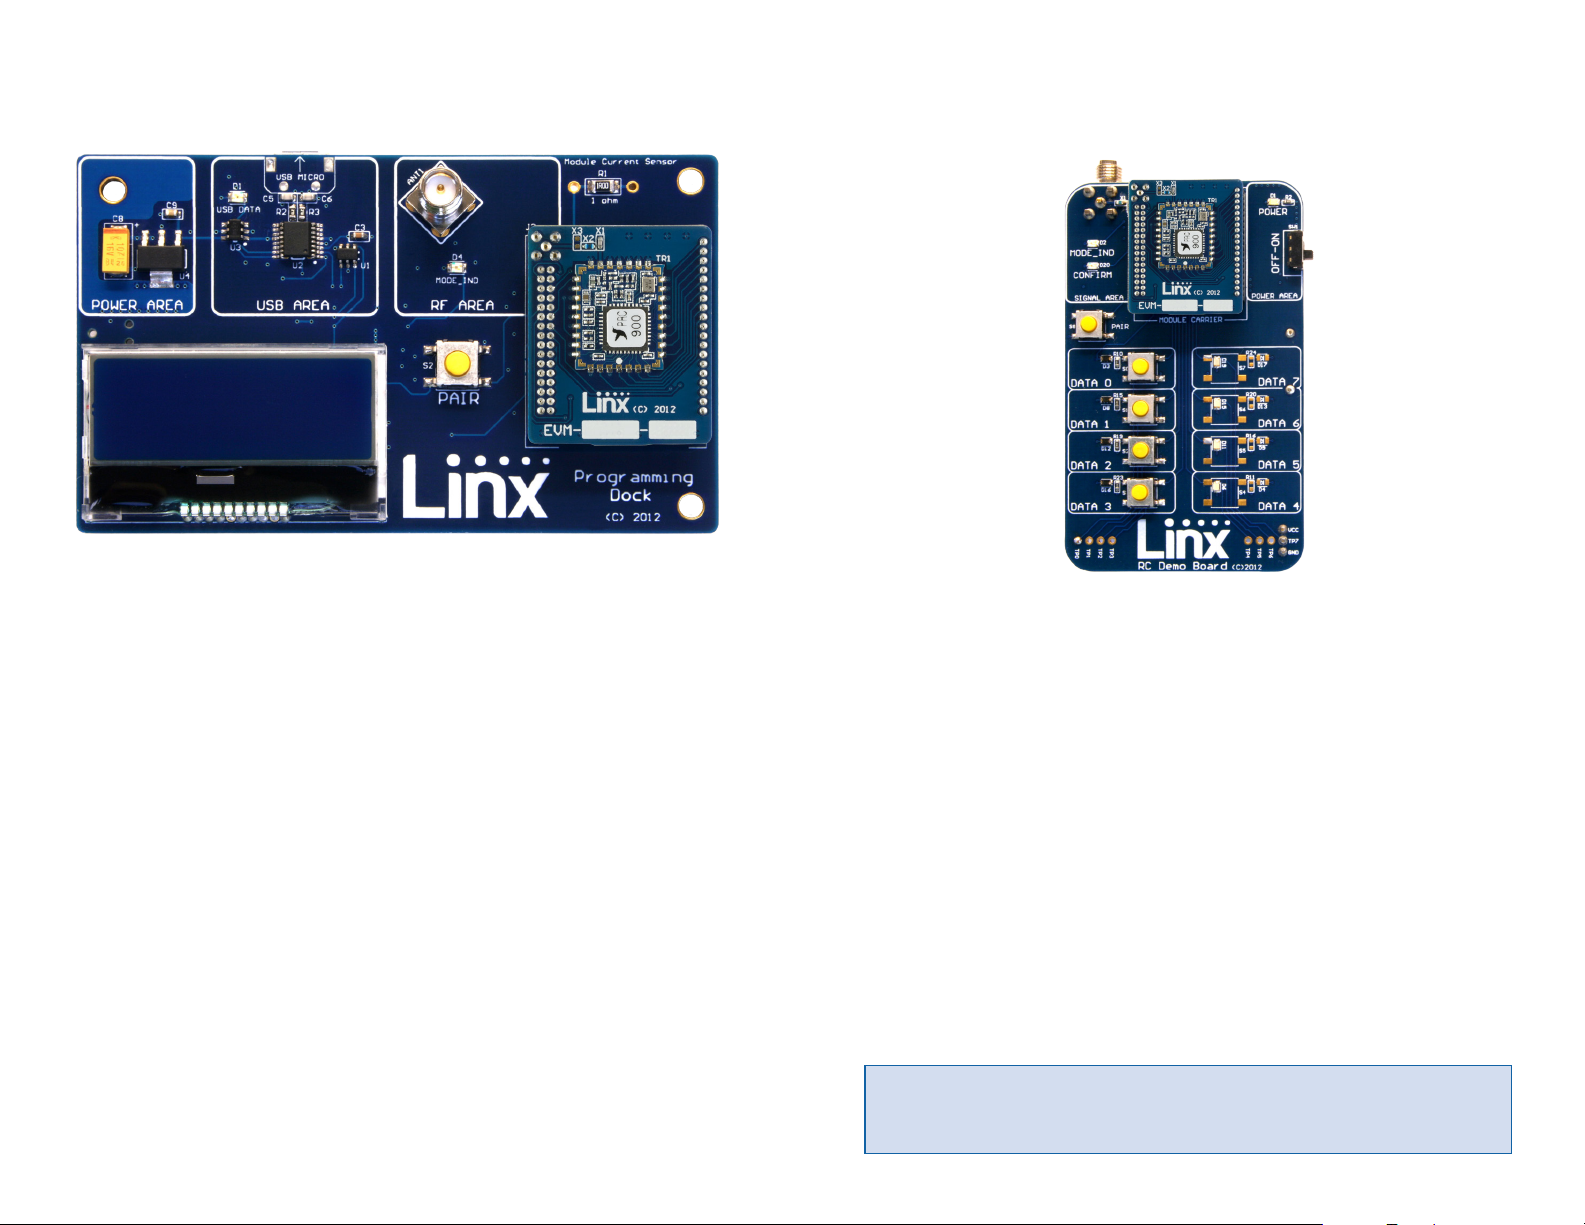
Using the Programming Dock
Snap a Carrier Board onto the socket on the Programming Dock as shown
in Figure 10.
Figure 10: Programming Dock with a Carrier Board
Using the Remote Control Demo Board
Snap a Carrier Board onto the socket on each Remote Control Demo
Board as shown in Figure 11.
Connect a micro USB cable into the connector at the top of the board.
Plug the other end into a PC. The board is powered by the USB bus.
The demonstration software included with the kit or custom application
software can be used to configure the module through its Command
Data Interface. The LCD is used to display information about the module.
This includes the module’s local address and a custom nickname. The
nickname is entered using the development kit software and can be
any name that helps distinguish the modules from one another. This is
convenient when multiple programming docks are connected to the same
computer. Please see the development kit software section for more
information on the nicknames.
The HumPRCTM Series transceiver has a serial Command Data Interface
that offers the option to configure the transceiver through software instead
of through hardware. This interface consists of a standard UART with a
serial command set.
Figure 11: Remote Control Demo Board with a Carrier Board
Insert 4 AAA batteries into the holders on the back of each board, connect
antennas and turn on power.
The modules come paired out of the box, but to pair additional modules,
ensure that one module is an Administrator (see page 17). Press the
PAIR button on both boards. The MODE_IND LEDs flash to indicate that
the modules are searching for each other and exchanging addresses. The
MODE_IND has a quick flash while searching (100ms on, 900ms off) and a
longer flash once Pairing is complete (400ms on, 100ms off). This process
only takes a few seconds. The pairing process accounts for the status line
input / output directions. If these are changed then the modules should be
paired again.
Once complete, pressing a button on one board (the Initiating Unit or IU)
causes an LED to light up on the other board (the Responding Unit or RU).
The RU sends an acknowledgement message to the IU. If the message is
valid, the IU turns on the CONFIRM LED.
Note: To restore the default configuration, push the PAIR button four
times and hold it down on the fifth press. The MODE_IND LED flashes
when it has reset.
– –
10 11
– –
Page 9
Range Testing
Several complex mathematical models exist for determining path loss in
many environments. These models vary as the transmitter and receiver are
moved from indoor operation to outdoor operation. Although these models
can provide an estimation of range performance in the field, the most
reliable method is to simply perform range tests using the modules in the
intended operational environment.
Range testing can be performed with the Remote Control Demo Boards.
To prepare the board for range testing, simply turn it on by switching the
power switch to the ON position. Pressing a status line button on one
board (the IU) activates an LED on the other board (the RU). The RU then
sends an acknowledgement back to the IU, which turns on the CONFIRM
LED. This indicates good bi-directional RF communications and lets the
user set one board down and walk with the other board.
As the maximum range of the link in the test area is approached, it is not
uncommon for the signal to cut in and out as the radio moves. This is
normal and can result from other interfering sources or fluctuating signal
levels due to multipath effects. This results in cancellation of the transmitted
signal as direct and reflected signals arrive at the receiver at differing times
and phases. The areas in which this occurs are commonly called “nulls”
and simply walking a little farther usually restores the signal. If the signal is
not restored, then the maximum range of the link has been reached.
To achieve maximum range, keep objects such as your hand away from
the antenna and ensure that the antenna on the transmitter has a clear and
unobstructed line-of-sight path to the receiver board. Range performance
is determined by many interdependent factors. If the range you are able to
achieve is significantly less than specified by Linx for the products you are
testing, then there is likely a problem with either the board or the ambient
RF environment in which the board is operating. First, check the battery,
switch positions, and antenna connection. Next, measure the receiver’s
RSSI voltage with the transmitter turned off to determine if ambient
interference is present. High RSSI readings while the transmitter off indicate
there is interference. If this fails to resolve the issue, please contact Linx
technical support.
Note: The Remote Control Demo boards are designed for hardware
configuration. If the modules are changed through software configuration
then the boards may not operate as expected. A restore to default
configuration can be used to reset the modules.
Using the Prototype Board
Snap a Carrier Board onto the socket on the Prototype Board as shown in
Figure 12.
Figure 12: Prototype Board with a Carrier Board
Place the power switch into the “USB” position then connect a micro USB
cable into the connector at the top of the board. Plug the other end into a
PC or any USB charger. The board is powered by the USB bus. This board
features a prototyping area to facilitate the addition of application-specific
circuitry. The prototyping area contains a large area of plated through-holes
so that external circuitry can be placed on the board. The holes are set at
0.100” on center with a 0.040” diameter, accommodating most industrystandard SIP and DIP packages.
At the top of the prototyping area is a row connected to the 3.3V power
supply and at the bottom is a row connected to ground. External circuitry
can be interfaced to the transceiver through the breakout headers. The
numbers next to the headers correspond to the pin numbers on the Carrier
Board. Figure 4 shows the pin assignments for the Carrier Board.
The OVERLOAD LED indicates that that too much current is being pulled
from the USB bus. This is used to prevent damage to the parts or the bus.
The overload condition is reset once the excess current draw is removed.
– –
12 13
– –
Page 10
Supply for the module is connected through R17. This can be removed and
replaced by another supply or used to measure the current consumption of
the module.
Note: The onboard 3.3-volt regulator has approximately 400mA
available for additional circuitry when plugged into a PC. If more current
is required, the user must power the board from an external supply or a
USB charger with more current capabilities, up to 1A.
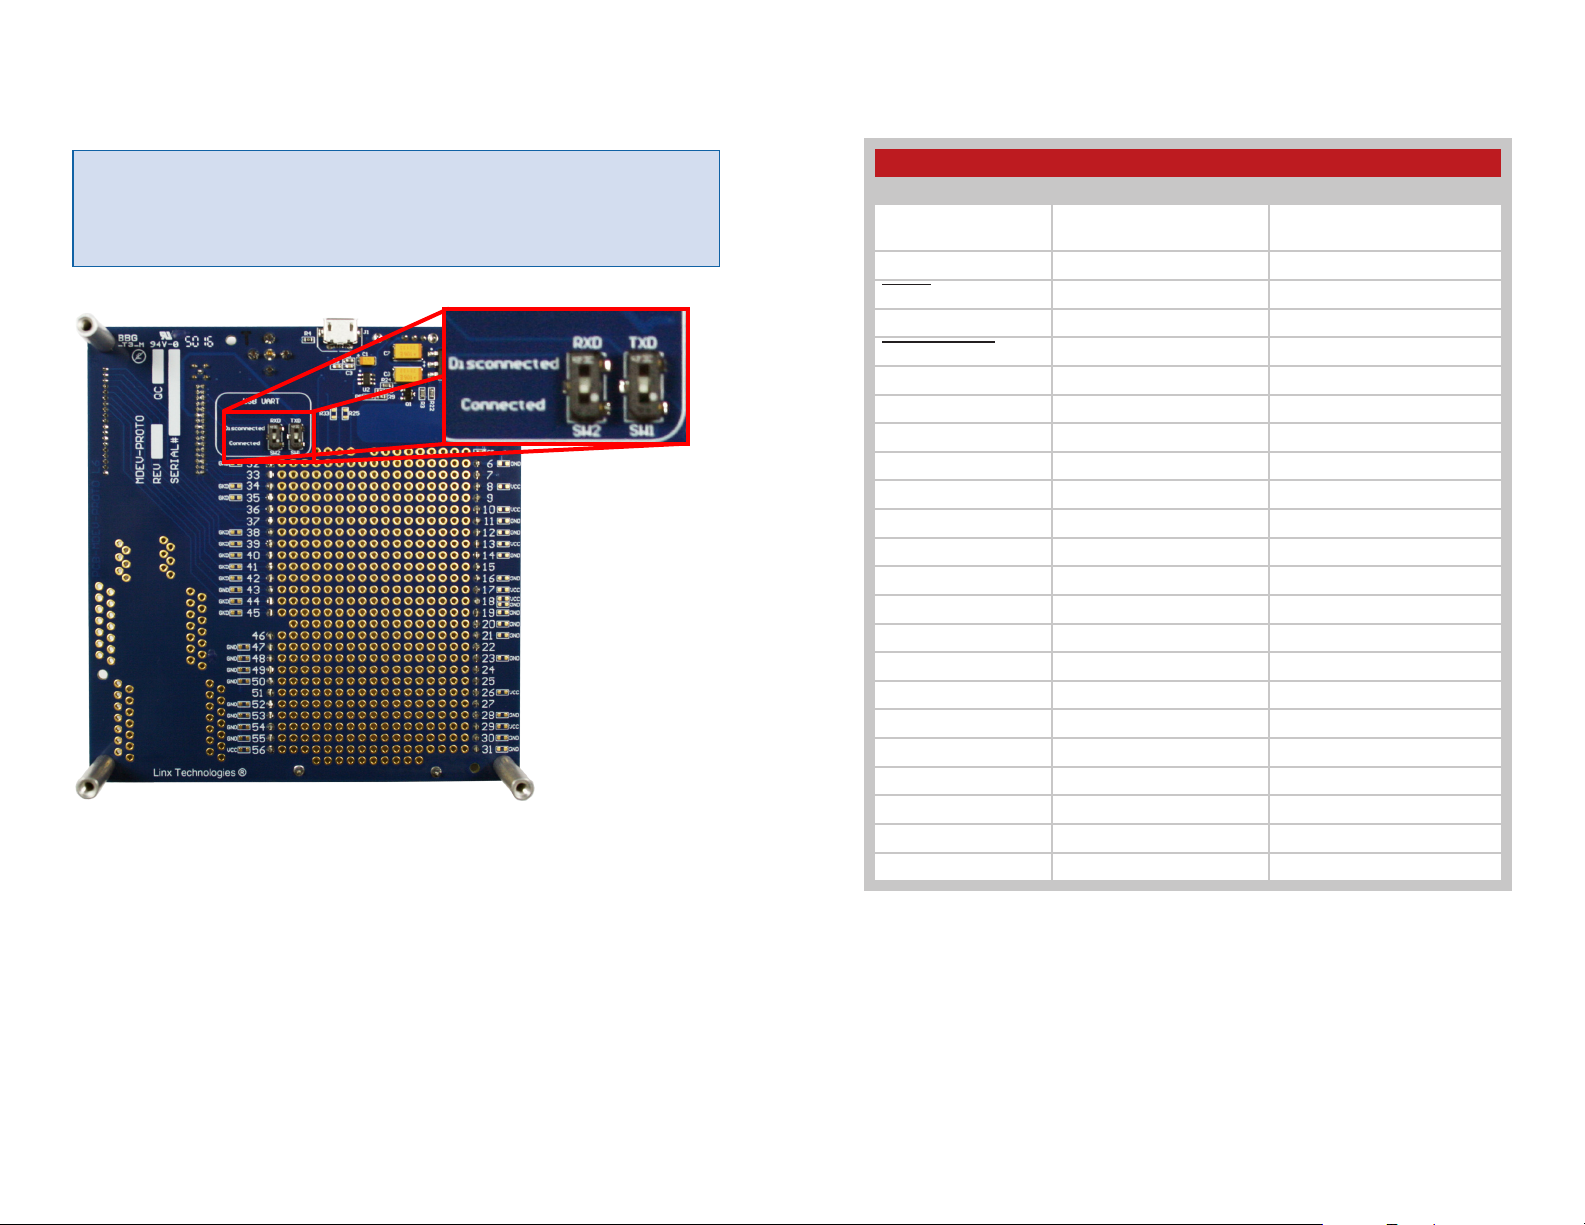
Figure 13 shows the bottom of the board.
Figure 13: Prototype Board Bottom Side
SW1 and SW2 connect the USB interface to the Command Data Interface
lines on the module. This allows the prototype board to be used with the
development kit software or a custom application. When in the “USB
Connected position”, the module is connected to the USB interface. The
“Header Only” position connects the module to the header. The prototype
board is shipped with the switches in the “Header Only” position.
Figure 14 shows a convenient cross reference showing which lines on the
module connect to which lines on the prototype board.
Module to Prototype Board Pin Number Cross Reference
Pin Name Module Pin Number Prototype Board Pin Number
GND
MODE_IND 30 7
RESET 22 8
CMD_DATA_IN 27 9
POWER_DOWN 12 10
LATCH_EN 13 11
ACK_EN 28 13
PAIR 29 14
CMD_DATA_OUT 26 15
LNA_EN 23 16
VCC 21 17
C0 10 19
PA_EN 24 20
C1 11 21
S0 8 38
S1 7 39
S2 6 40
S3 5 41
S4 4 42
S5 3 43
S6 2 44
S7 1 45
ACK_OUT 31 46
Figure 14: Module to Prototype Board Pin Number Cross Reference
9, 14, 15, 16, 17, 18, 20,
25, 32
6
Footprints for 0603 size resistors are on most lines so that pull-ups or
pull-downs can easily be added to the lines. The pads are connected to
VCC or GND based on the most common configuration for the module. The
schematic at the end of this document shows how each line is connected.
– –
14 15
– –
Page 11
Using the Handheld Transmitter Evaluation Board
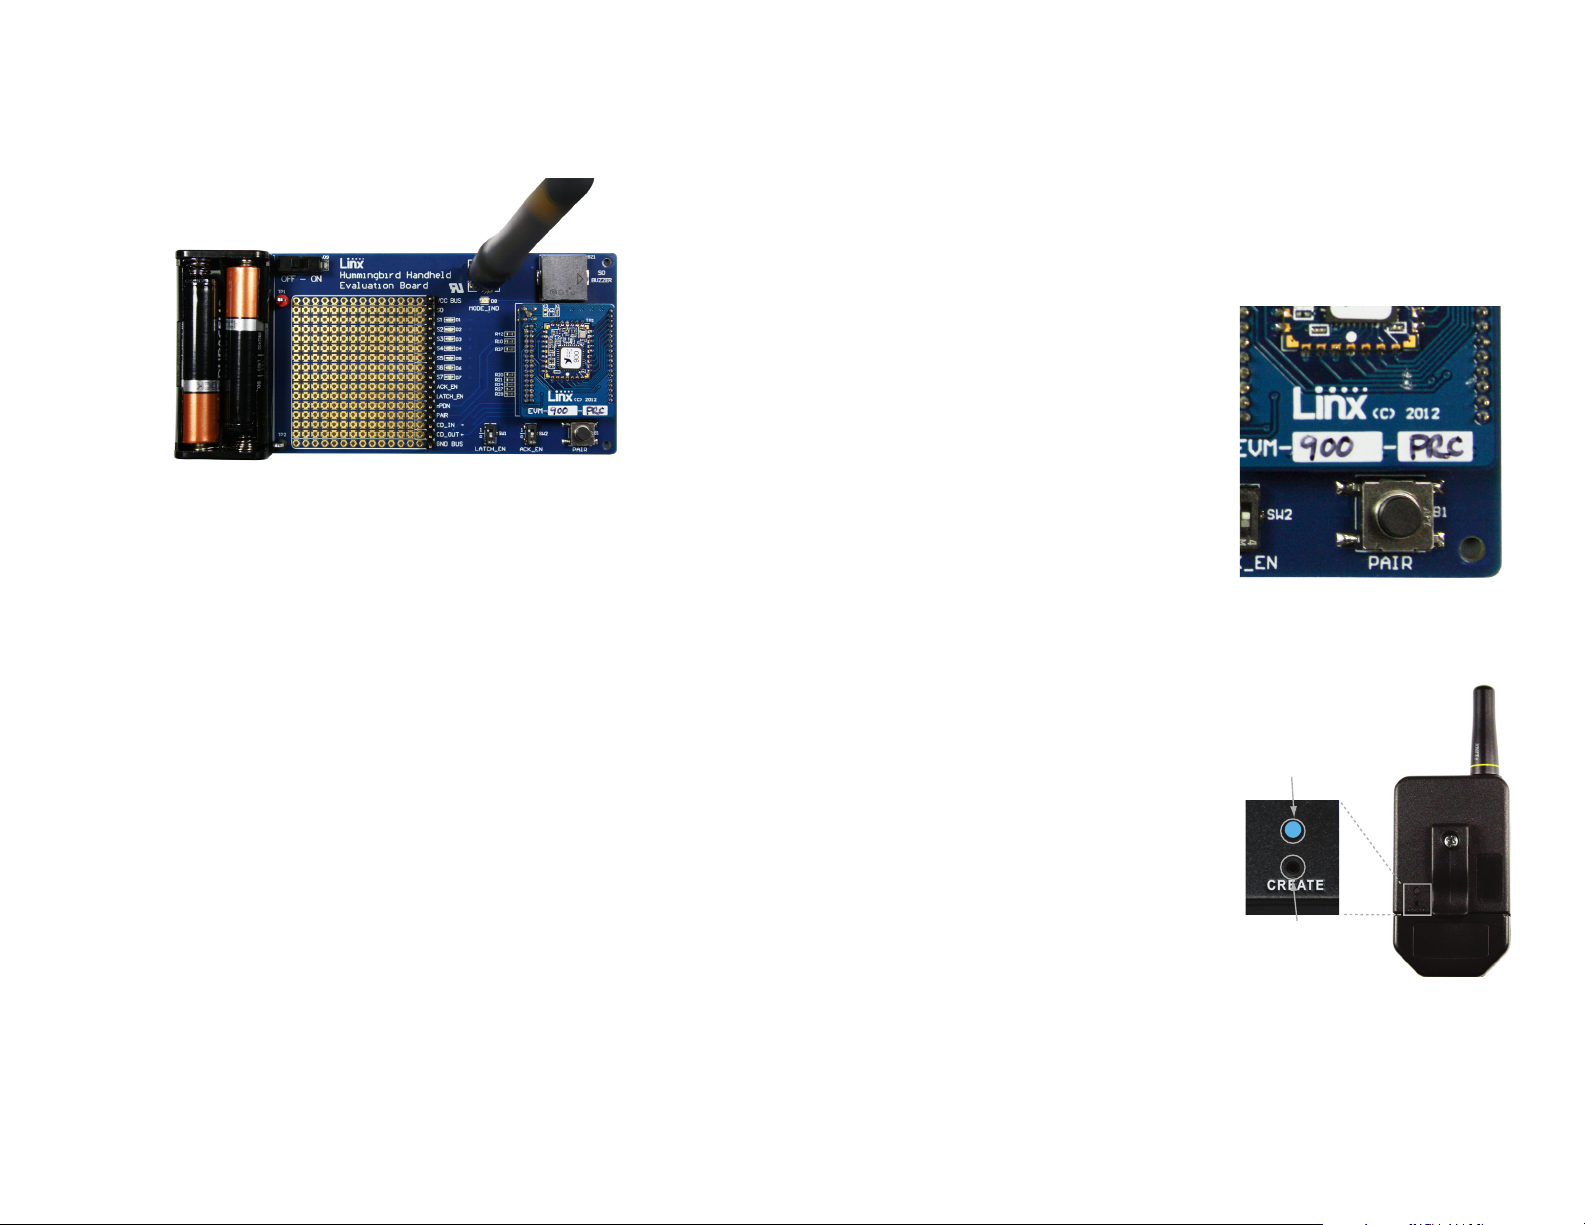
Snap a Carrier Board onto the socket on the Handheld Transmitter
Evaluation Board and install the batteries and an antenna as shown in
Figure.
Figure 15: Assembled Handheld Transmitter Evaluation Board
The receiver board is powered by two AAA batteries. A Linx HumPRCTM
Series transceiver is used for reception of the transmitted signal. This
receiver provides exceptional sensitivity, allowing the transmitter and
receiver to operate at distances of up to 0.8 mile (1,300m) depending on
signal conditions. The data recovered by the transceiver is validated and
if everything is correct, the status line outputs are updated to match the
states of the buttons on the transmitter. To demonstrate this, one status
line on the evaluation board is used to drive a buzzer while the other
lines activate LEDs. The board also has a prototyping area with all of the
transceiver lines brought out to a header.
Turn on the power to the board, and press a button on the handheld
transmitter. When S0 is pressed, the buzzer sounds; when S1–S7 are
pressed, the LEDs turn on. When any button (S0–S7) is pressed on the
transmitter, the corresponding output (S0–S7) is active high (VCC) on the
prototyping header.
Simple range testing can be performed with the transmitter and Evaluation
Board by placing the board in a stationary location and walking away with
the transmitter. When in good signal range, as a button is pressed on the
transmitter, the buzzer will sound or an LED will light up on the Evaluation
Board. Also, the Acknowledgement LED will light on the transmitter.
When the Evaluation Board no longer activates and moving around a
few feet does not restore operation, the maximum range in the operating
environment has been reached.
Joining a Transmitter
The transmitter is associated with a receiver using the built-in Join
Process. This process configures a star network with the central unit as
the system Administrator. Other units are added to the network as nodes
one at a time. Typically, the handheld transmitter is added as a node to a
module that has been configured as an administrator. While transmitters
and evaluation board are paired at the factory, the following procedure
describes how to configure the evaluation board and pair a transmitter.
Configure the evaluation board as an
Administrator by pressing and holding
the PAIR button for 30 seconds. While
the button is held, the MODE_IND line
is on. After 30 seconds, the MODE_IND
line repeats a double blink, indicating
that the operation has begun. When the
button is released the key and address
generation are complete and the module
is an Administrator. A full explanation of
this operation is in the HumPRCTM Series
data guide.
The handheld transmitter is joined
to an Administrator by pressing and
releasing the PAIR buttons on both
units. The modules automatically
search for each other using a special
protocol. When they find each
other, the administrator sends the
node the encryption key, UMASK
and its network address. The
UDESTID is set to the address of
the administrator. The values are
encrypted using a special factorydefined key. Once the JOIN process
is complete, the MODE_IND blinks on
both units and they now operate together.
Figure 16: Evaluation Board PAIR Button
MODE_IND Window
PAIR Button
Figure 17: Transmitter PAIR Button Access
– –
16 17
– –
Page 12
The Development Kit Demonstration Software
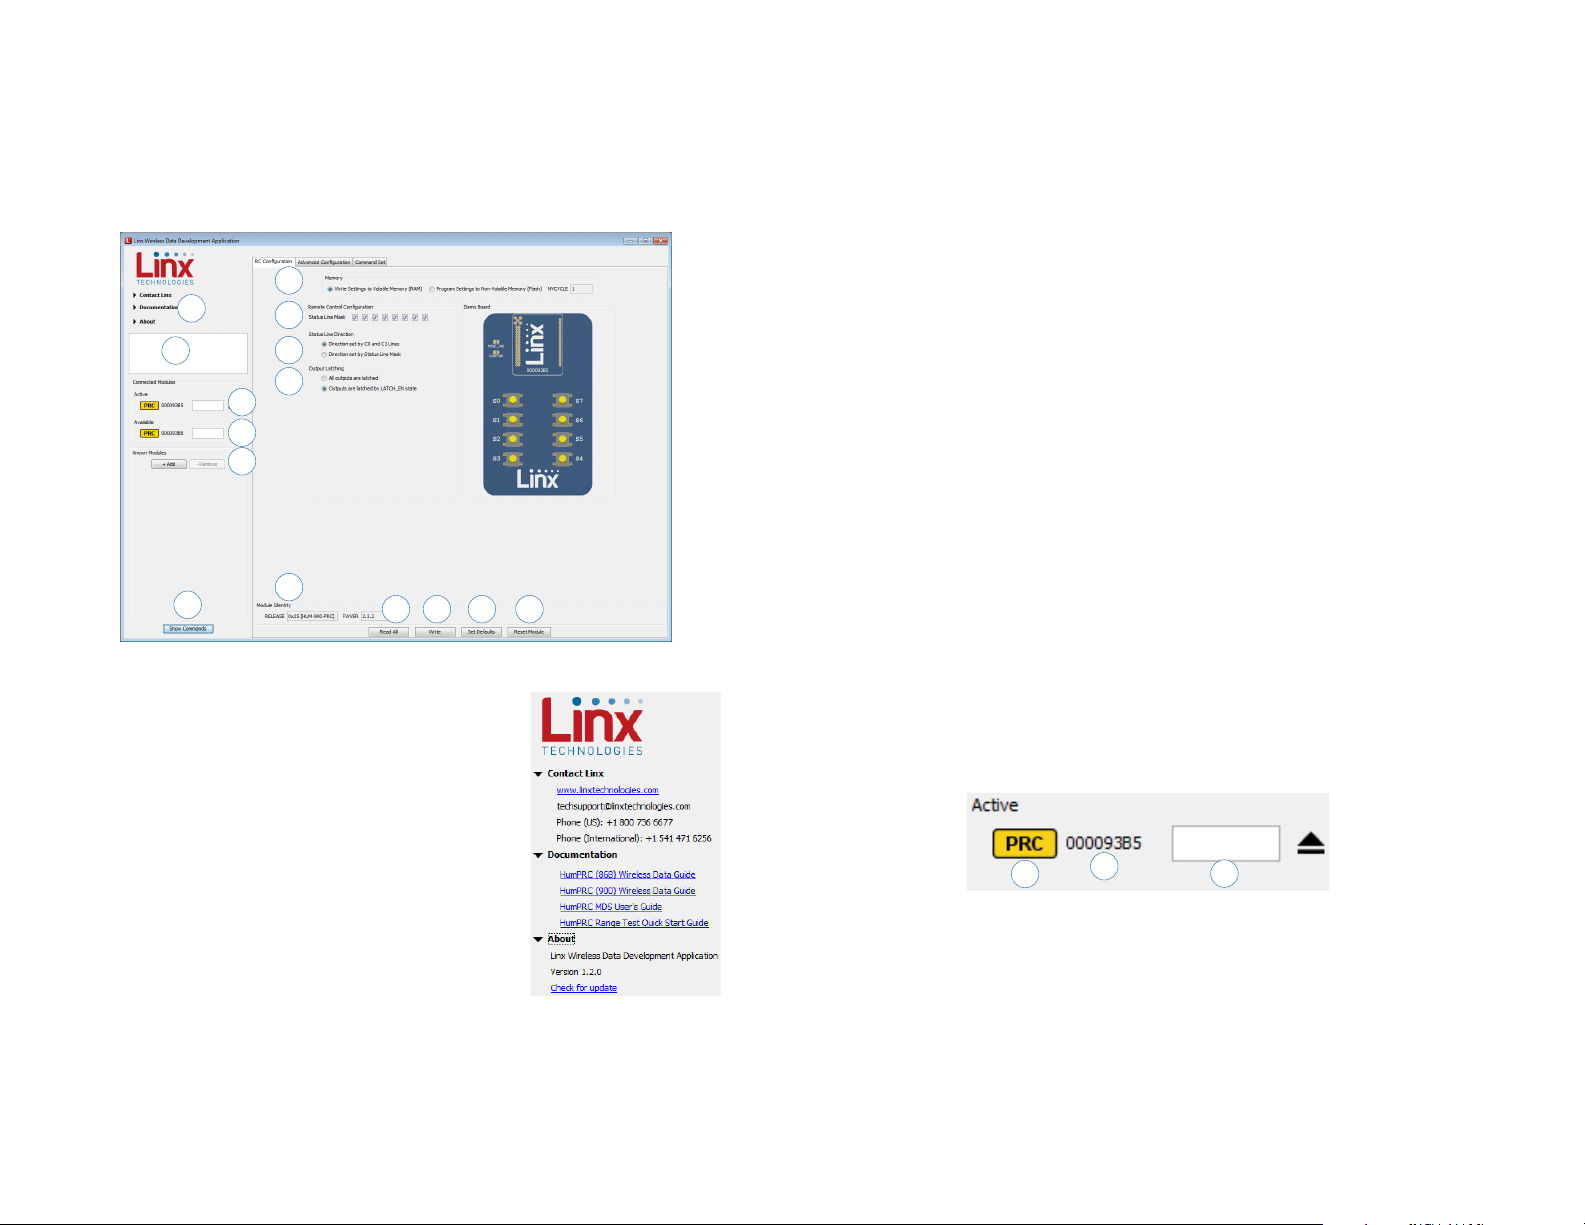
The development kit includes software that is used to configure and control
the module through the Programming Dock. The software defaults to the
RC Configuration tab when opened (Figure 18). This window offers basic
configuration and demonstration of the module’s functionality with the
current configuration.
6
1
2
15
Figure 18: The Master Development System Software Demo and EZConfiguration Tab
1. Clicking the Contact Linx, Documentation and
About labels on the left side expands them to
show additional information and links to the
latest documentation. This is shown in Figure 19.
2. The Help window shows tips and comments
about the software.
3. The active module is connected to the PC and
being configured by the software.
4. Available modules are connected to the PC but
are not currently being configured or controlled
by the PC
5. Known Modules are not currently connected to
the PC, but have either been connected to the
software in the past or have been manually entered.
6. The Memory group selects if changes are written to volatile or
non-volatile memory.
7
8
9
3
4
5
10
11
12 13 14
Figure 19: Additional Information
7. The Status Line Mask selects the input / output direction of the
individual status lines. A checked box sets that line as an input, an
unchecked box is an output. The Status Line Direction needs to be
configured before this can be changed. Settings are reflected in the
image on the right.
8. The Status Line Direction option determines if the input / output
direction of the status lines is set by the C0 and C1 lines or the Status
Line Mask
9. The Output Latching option sets the outputs as either all latched or
set by the LATCH_EN line on the module. Settings are reflected in the
image on the right.
10. The Module Identity group displays the Release and Firmware Version
of the active module.
11. The Read All button reads all of the active module’s configurations and
updates the items in the window.
12. The Write button writes the changed configurations to the selected
memory location of the active module.
13. The Set Defaults button returns the module to the factory default
configurations.
14. The Reset Module button issues a soft reset that causes the module to
reboot. This sets all volatile memory configurations to the non-volatile
default values.
15. The Show Commands button opens a larger window to view the serial
commands sent to and received from the module.
The modules are shown with three identifiers as shown in Figure 20.
1
Figure 20: The Master Development System Software Module Identifiers
2
3
1. The type of module (HumPRC™ Series)
2. The module’s local address.
3. A custom name that can be given to the module. Type a name into
the box and press Enter to apply it. This name is shown on the LCD
display on the programming dock.
– –
18 19
– –
Page 13
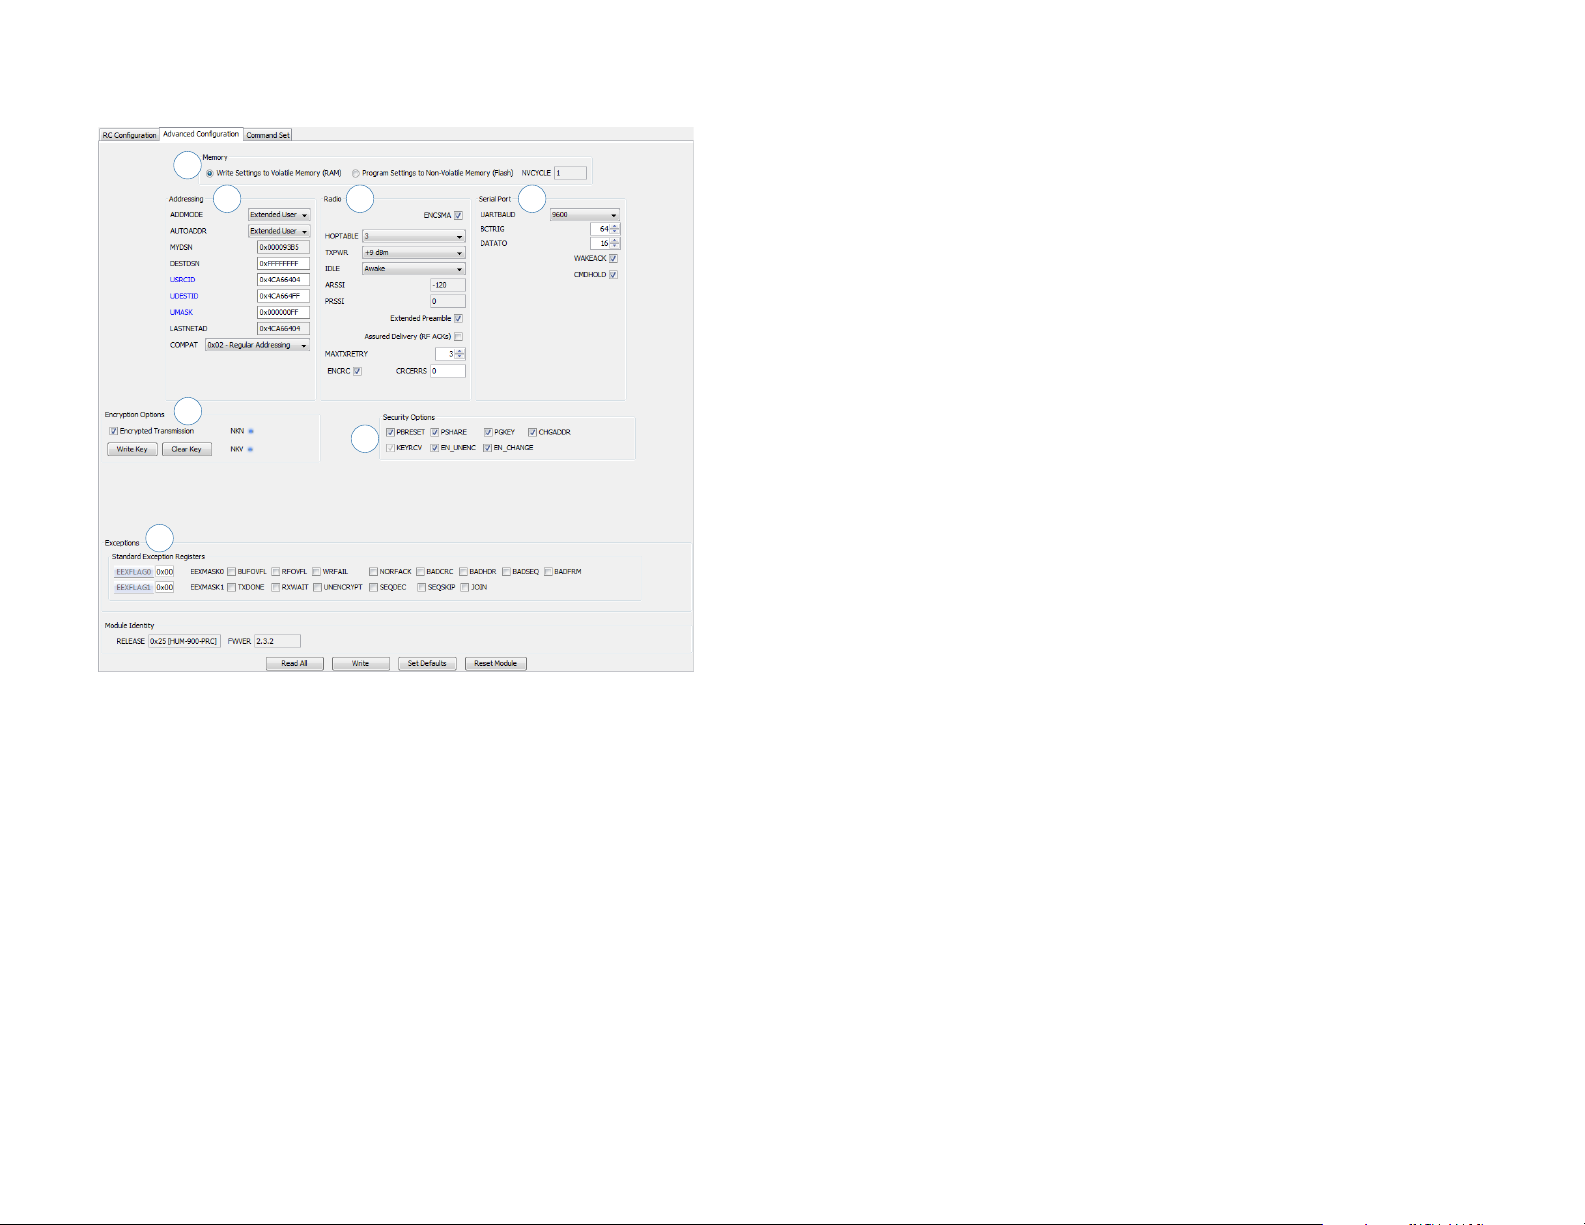
The Advanced Configuration tab (Figure 21) offers more detailed
configuration options for the active module.
1
2 3
5
6
7
Figure 21: The Master Development System Software Advanced Configuration Tab
4
1. The Memory group selects if changes are written to volatile or
non-volatile memory.
2. The configurations are divided into groups. The Addressing group
configures the addressing features of the module.
• The Addressing Mode (ADDMODE) menu sets the addressing mode
used by the module; either DSN, User or Extended User.
• The Auto Addressing (AUTOADDR) menu turns the automatic
addressing feature on and off.
• The MYDSN address is the module’s local address. This is configured
at the factory and cannot be changed.
• The DSN Destination Address (DESTDSN) is the address of the desired
destination module when DSN addressing mode is used.
• User Source Address (USRCID) is the module’s local address when
User and Extended User modes are used.
• User Destination Address (UDESTID) is the address of the destination
module when User and Extended User addressing modes are used.
• User ID Address Mask (UMASK) is the mask for screening incoming
packets.
• The LASTNETAD is the last address that the module assigned using
the JOIN process. This is only used if encryption is used and the
module is an administrator.
• The Compatibility (COMPAT) setting allows communication with legacy
products. COMPAT = 0x00 is not available with the 868MHz module.
3. The Radio group configures the radio settings of the module.
• For 900MHz units, checking the ENCSMA box enables the Carrier
Sense Multiple Access feature.
• The HOPTABLE menu selects the module’s hopping pattern
• The TXPWR menu sets the module’s transmitter output power.
• The IDLE menu sets the module’s operating state as awake or asleep.
• The ARSSI measurement is the ambient RSSI in the local environment
on the current channel at the time when the read command is issued.
• The PRSSI is the RSSI measurement of the last valid packet that was
received.
• Checking the Extended Preamble box configures the module to send a
long preamble at the beginning of every packet.
• Checking the Assured Delivery box enables RF acknowledgements
and retries when an acknowledgement is not received.
• MAXTXRETRY sets the maximum number of times that the module will
retry sending the packet before an exception is thrown.
• Checking the ENCRC box enables the CRC checks on the incoming
data. The CRC Errors box shows the number of errors since the last
power cycle or the last time the count was reset.
4. The Serial Port group configures all of the UART serial port settings.
• The UARTBAUD menu configures the serial port baud rate, which is
used by the module to set the over-the-air RF data rate.
• The Byte Count Trigger (BCTRIG) sets the number of bytes that the
UART receives before triggering the transmission of a packet.
– –
20 21
– –
Page 14
• The UART Data Timeout (DATATO) sets the number of milliseconds
from the last character received on the UART before the module
transmits the data in its buffer.
• Selecting the WAKEACK box instructs the module to output the
acknowledgement (0x06) on the UART when the module wakes from
sleep or power cycle.
• Selecting the CMDHOLD box instructs the module to buffer any
received over-the-air data while processing configuration commands.
5. The Encryption Options group configures the encryption settings.
• Selecting the Encrypted Transmission box enables encryption.
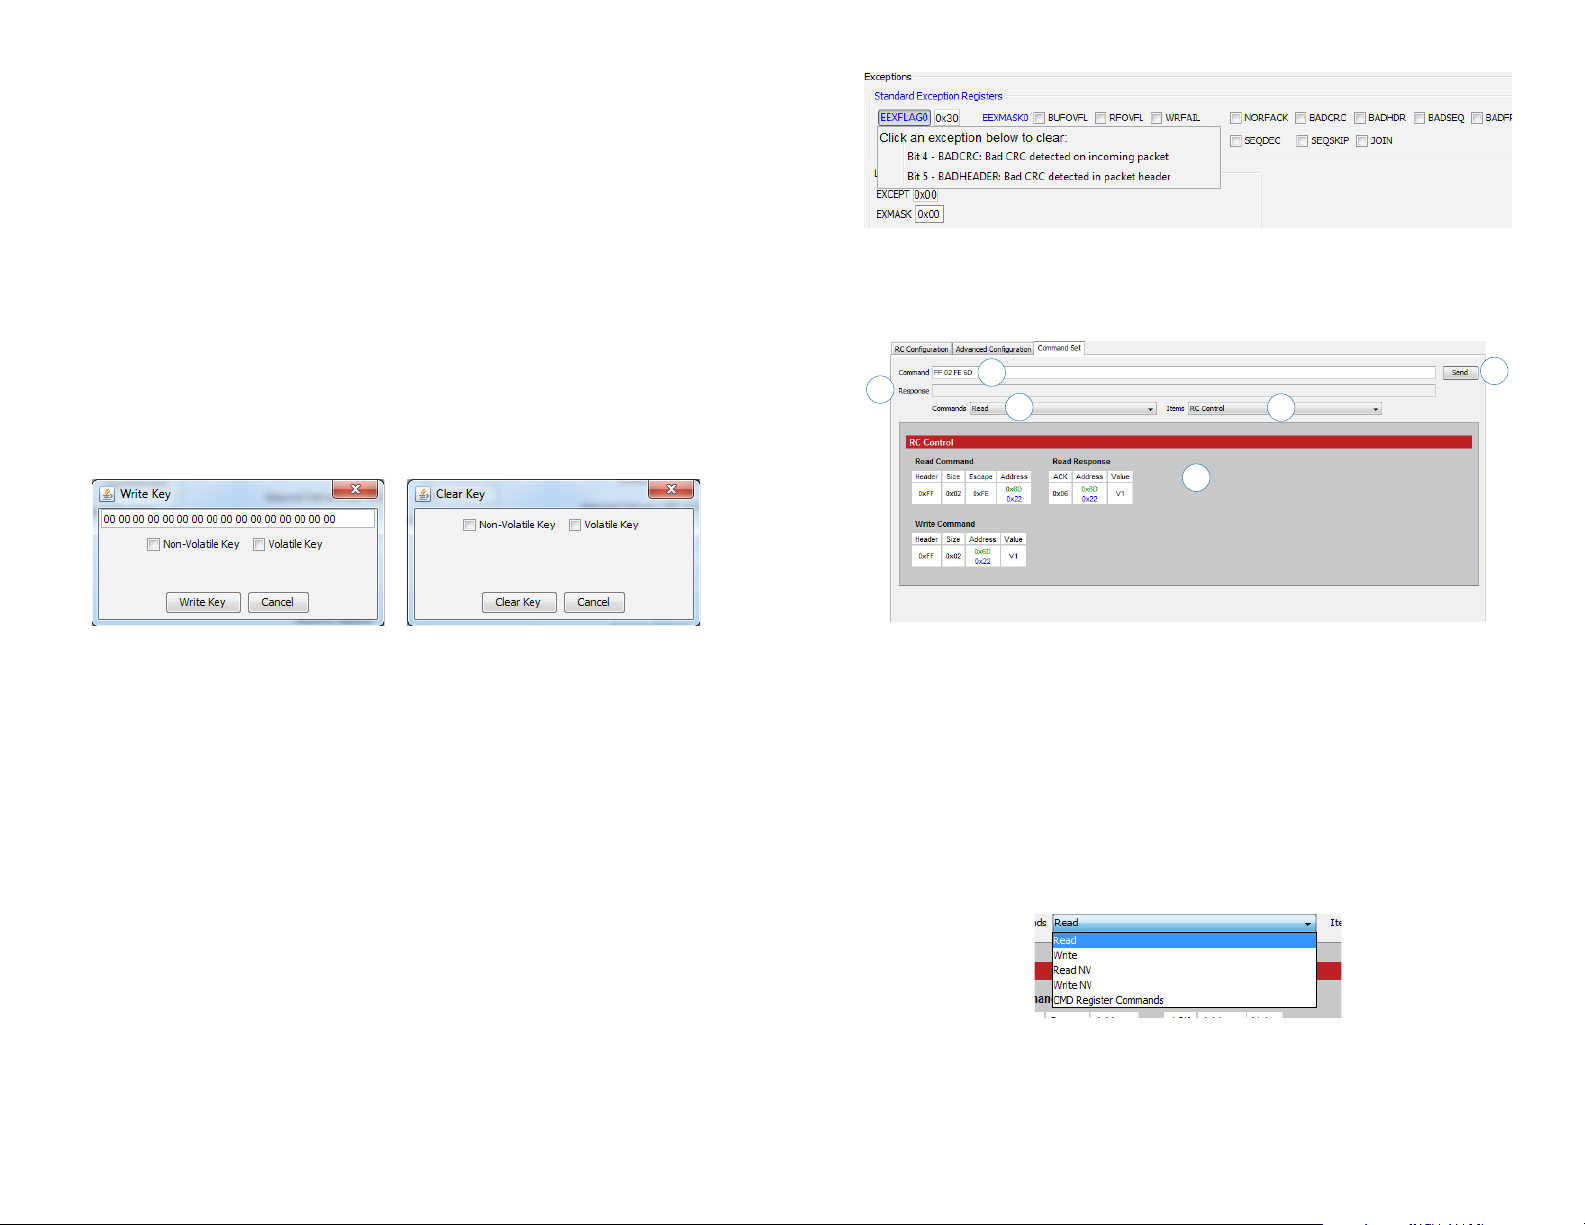
• Clicking the Write Key button opens a window where the 128-bit AES
key can be entered (Figure 22).
• Clicking the Clear Key button opens a window where the key can be
cleared (Figure 22).
Figure 23: The Master Development System Software Exception Flags
The Command Set tab (Figure 24) allows specific commands to be written
to the module.
2
1
3
6
4
5
Figure 22: The Master Development System Software Write Key and Clear Key Windows
6. The Security Options group corresponds to the SECOPT register.
This configures the security options related to encryption and the Join
Process for setting up networks.
7. The Exceptions group configures the Extended Exception Flags and
Extended Exception Mask.
• Checking the boxes in the EEMASK0 and EEMASK1 rows sets which
exception conditions trigger the exception flags
• The EEXFLAG0 and EEXFLAG1 boxes show the current value for the
flags. 0x00 means no exceptions were detected. A non-zero value
means an exception flag is set. Clicking on the box opens a menu
showing which flags are set. Clicking on the flag clears it (Figure 23).
– –
22 23
Figure 24: The Master Development System Software Command Set Tab
1. The Command box shows the hexadecimal values that are written to
the module. Values can be typed into the box or a command can be
selected from the Commands menu.
2. The Response box shows the hexadecimal values that are returned
from the module in response to a command.
3. The Commands drop-down menu shows all of the commands that
are available for the active module (Figure 25). Selecting one of the
commands from this menu automatically fills in the Command box. The
values can be adjusted by typing in the box.
Figure 25: The Master Development System Software Command Set Tab Commands Menu
– –
Page 15
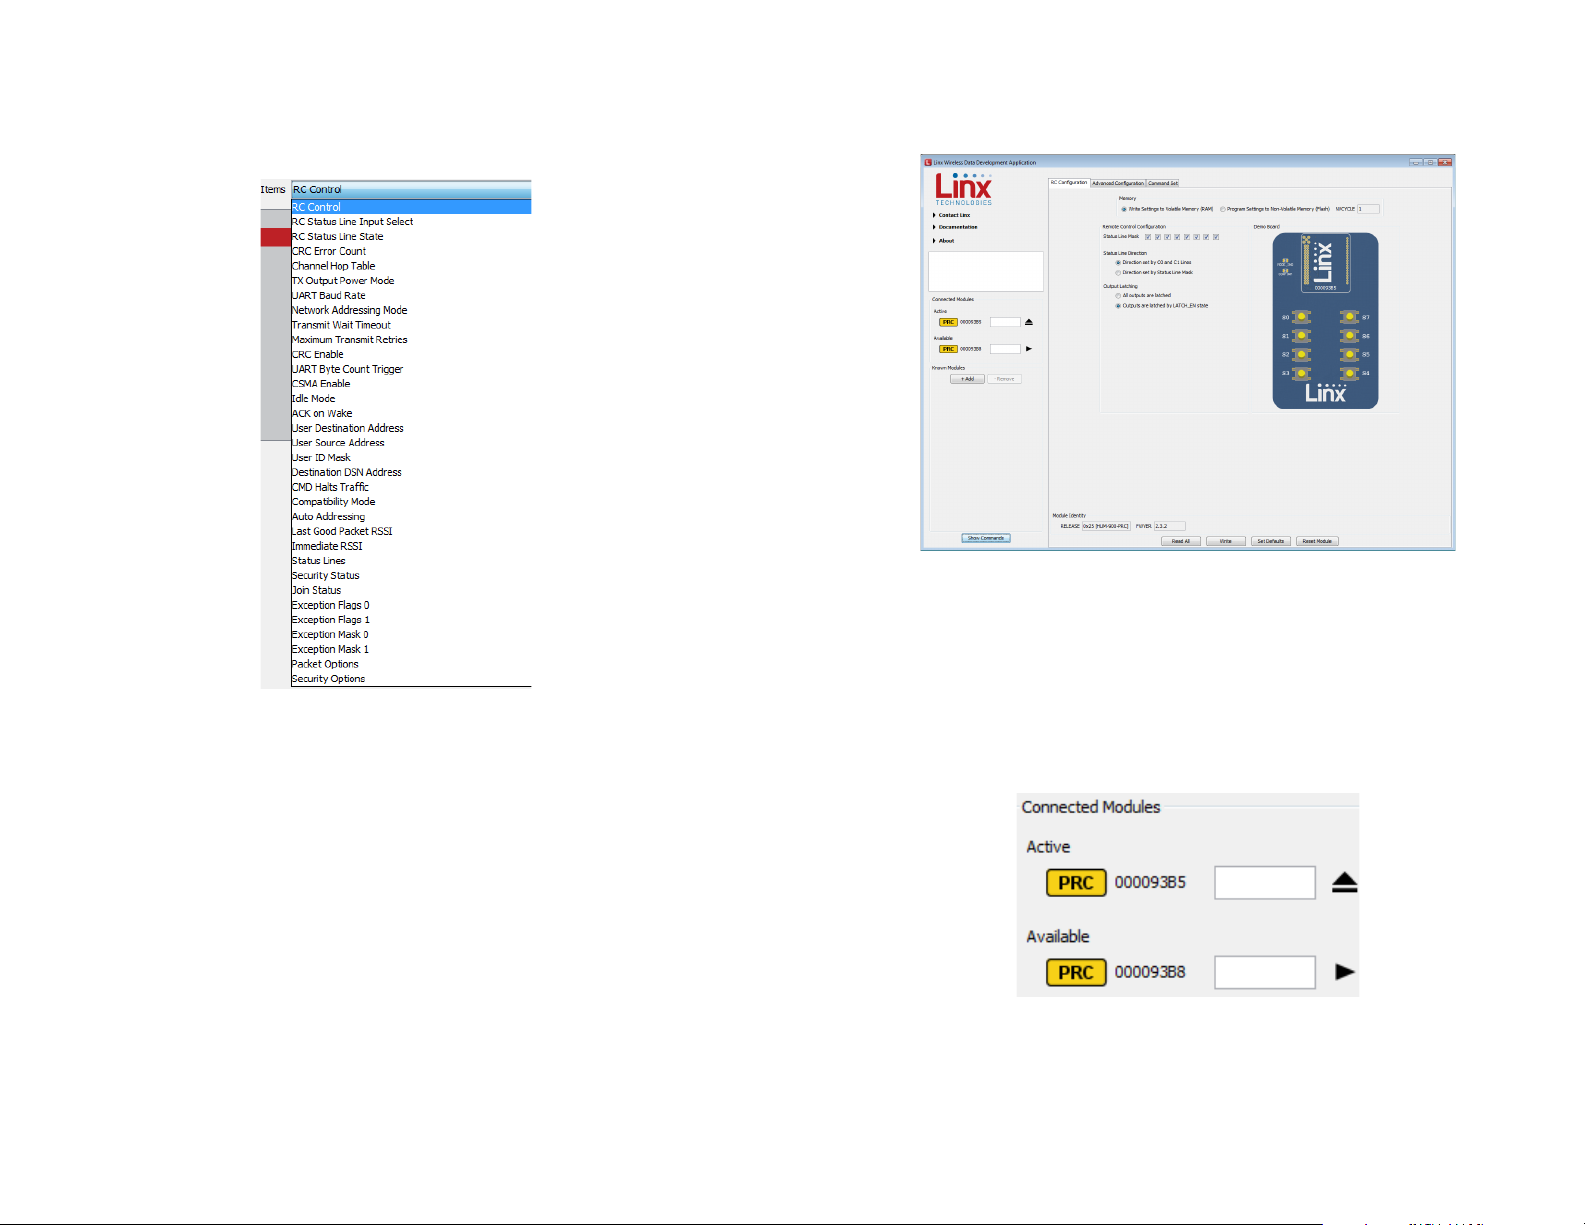
4. The Items drop down menu displays all of the items that are available
for the active module (Figure 26). Selecting one of the items from
this menu automatically fills in the Command box. The values can be
adjusted by typing in the box.
Figure 26: The Master Development System Software Command Set Tab Items Menu
5. Clicking the Send button writes the values in the Command box to the
module.
6. The structure of the selected command and its response is shown in
the main window. Please see the HumPRC™ Series Transceiver Data
Guide for definitions of each value.
Development Kit Demonstration Software Example
This example shows how to configure a module using the development kit
software. The software defaults to the RC Configuration tab (Figure 27).
Figure 27: The Master Development System Software RC Configuration Tab
Install a Carrier Board onto the Programming Dock and plug a USB cable
between the Programming Dock and the PC. The software automatically
detects attached devices. The first module that is identified appears
under the Active label. This is the module that is actively controlled by
the software. Subsequent modules are listed under the Available label as
shown in Figure 28.
Figure 28: The Master Development System Software Connected Modules
– –
24 25
– –
Page 16
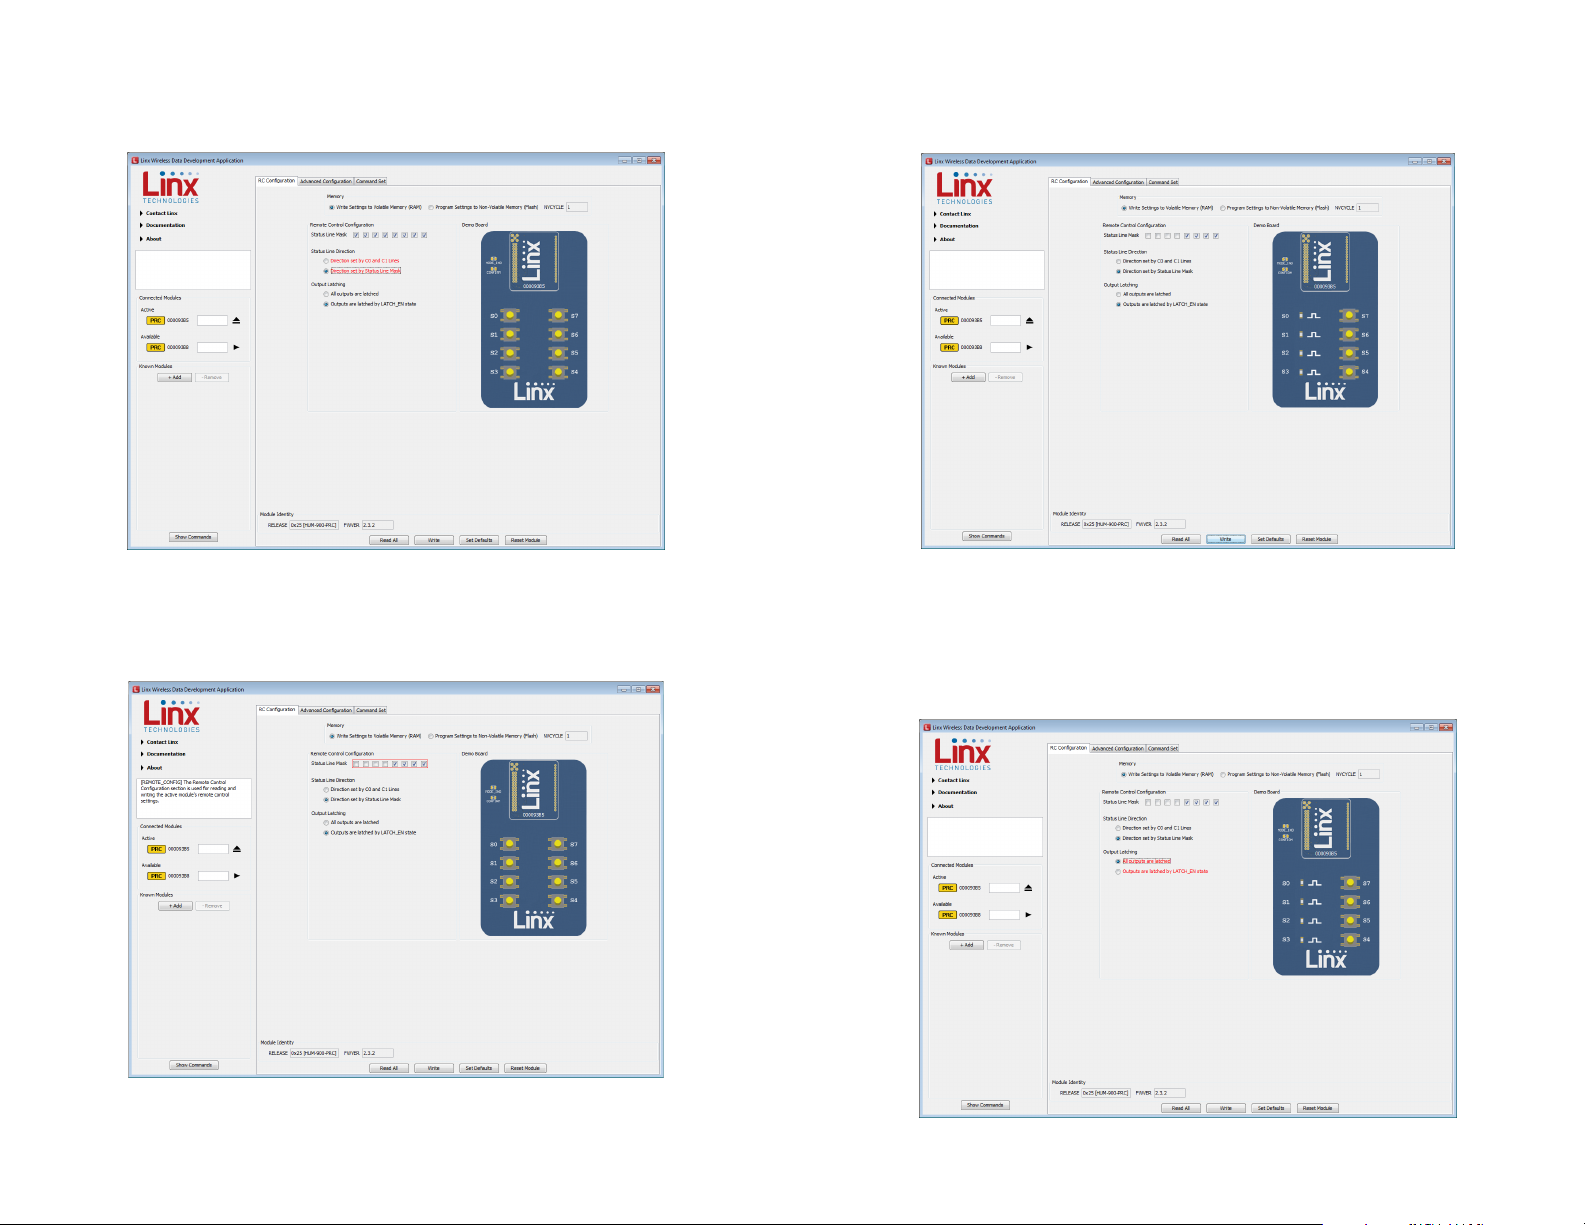
To change the status line directions, first change the Status Line Direction
option to “Direction set by Status Line Mask.” The change is highlighted in
red (Figure 29). Click the Write button to write the change to the module.
When the Write button is clicked, the new states are written to the module
and are reflected in the model to the right. All lines that were unchecked
become outputs represented by LEDs (Figure 31).
Figure 29: The Master Development System Changed Status Line Direction
Then change the Status Line Mask as desired. Checked boxes are set as
inputs for buttons (Figure 30).
Figure 30: The Master Development System Changed Status Line Mask
Figure 31: The Master Development System Software Configured Module
The lines can be configured as momentary or latched. By default, this is
set by the logic state of the LATCH_EN line on the module. All of the lines
can be set as latched by selecting the “All output are latched” option and
clicking the Write button (Figure 32).
Figure 32: The Master Development System Software Changed Latch Status
– –
26 27
– –
Page 17
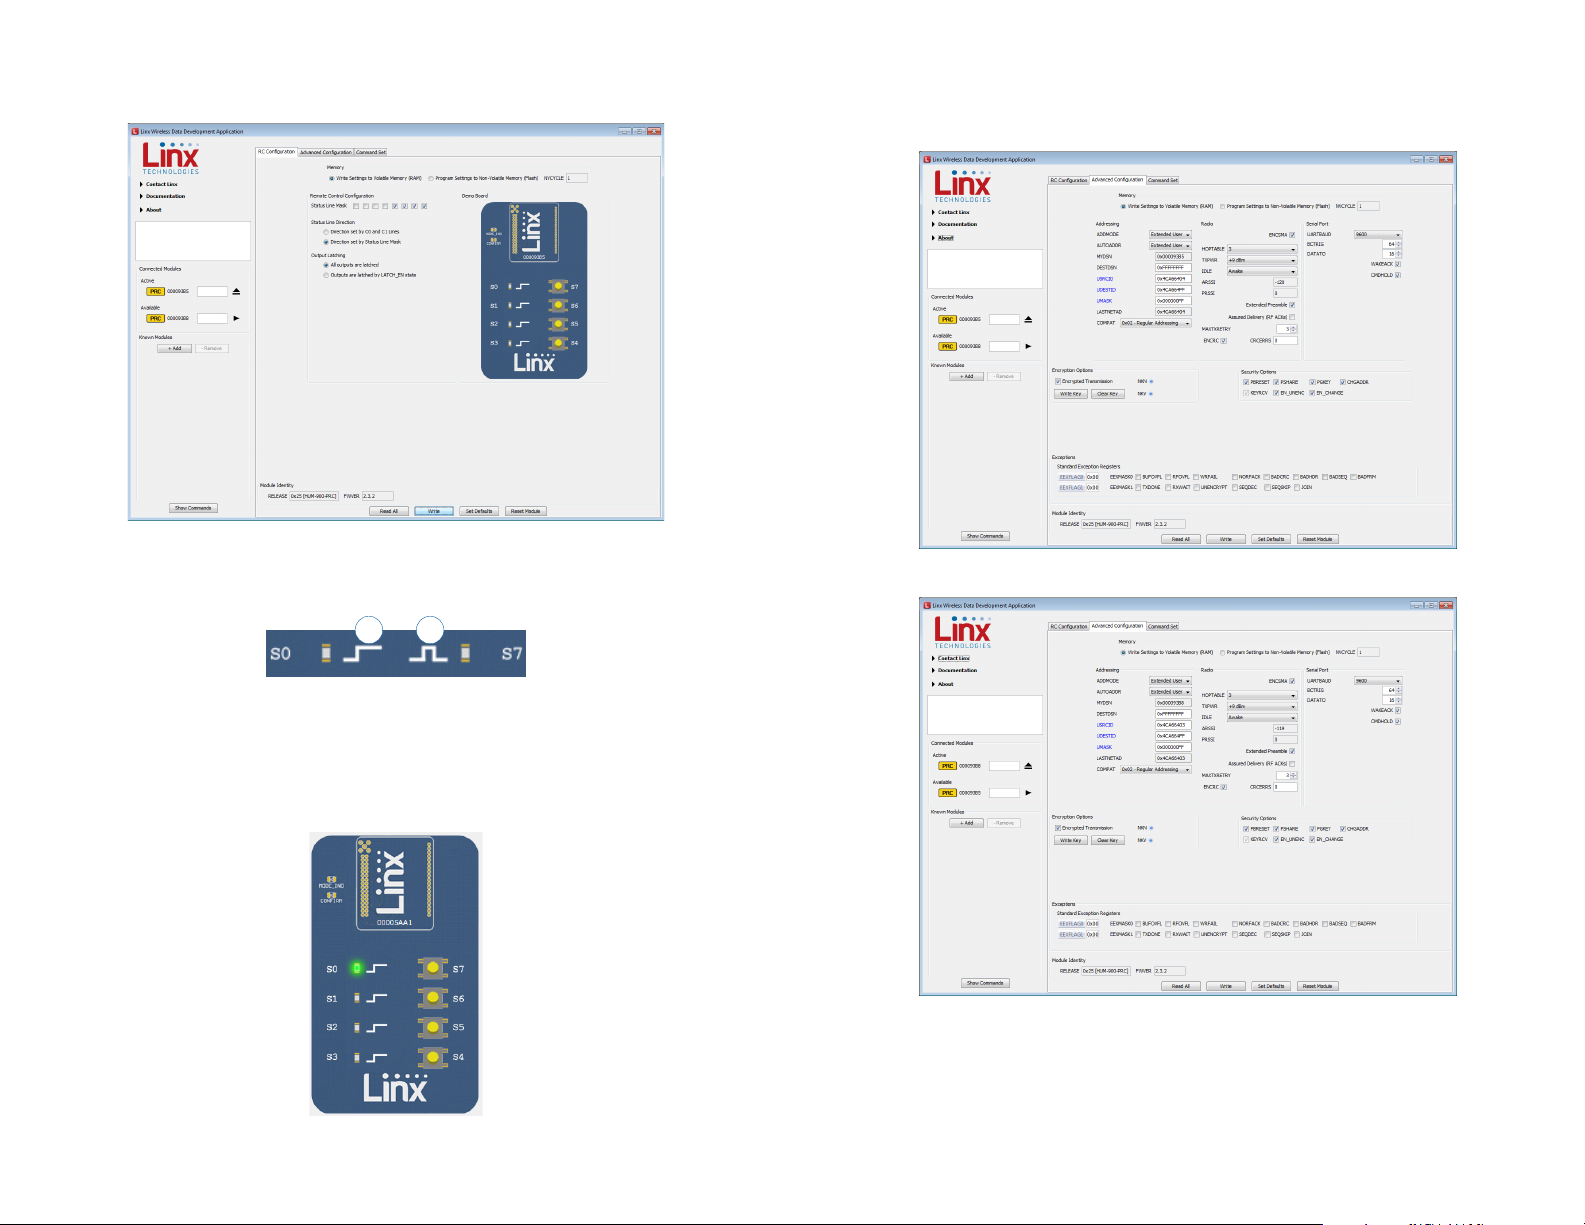
When the latched configuration is written to the module, the symbol next to
the LEDs changes to reflect the operation (Figure 33).
Figure 33: The Master Development System Software Configured Module
Figure 34 shows the latching and momentary symbols.
1 2
The Advanced Configuration tab shows the addressing and radio
configurations for the module. Figure 36 and Figure 37 show the tab for
two modules.
Figure 36: The Master Development System Software Module 1 Advanced Configuration Tab
Figure 34: The Master Development System Software Latching (1) and Momentary (2) Symbols
The software continuously polls the module checking the state of its
outputs. When it detects that the module has taken a line high, this is
reflected in the software as an active LED (Figure 35).
Figure 35: The Master Development System Software Activated Module
– –
28 29
Figure 37: The Master Development System Software Module 2 Advanced Configuration Tab
In the Addressing group, the MYDSN is the unique serial number for each
module. The modules are configured by the Join Process to use Extended
User address mode. This makes use of the USRCID, UDESTID and
UMASK fields.
– –
Page 18
The Join Process selects a random 3-byte number that is used as a
network address. This is placed in the upper 3 bytes of the module’s local
source address (USRCID) and the destination address (UDESTID). In this
example, the number is 0x4CA664. The last byte in the USRCID field is the
module’s unique address, in this case 0x03 and 0x04 for the two modules.
The UMASK value is 0x000000FF. This divides the address into two
groups. All of the address bits in a received message represented by the
‘0’s must match the local USRCID exactly in order for the message to be
accepted. In this case, the UDESTID address in a received packet must be
0x4CA664 or the packet is rejected.
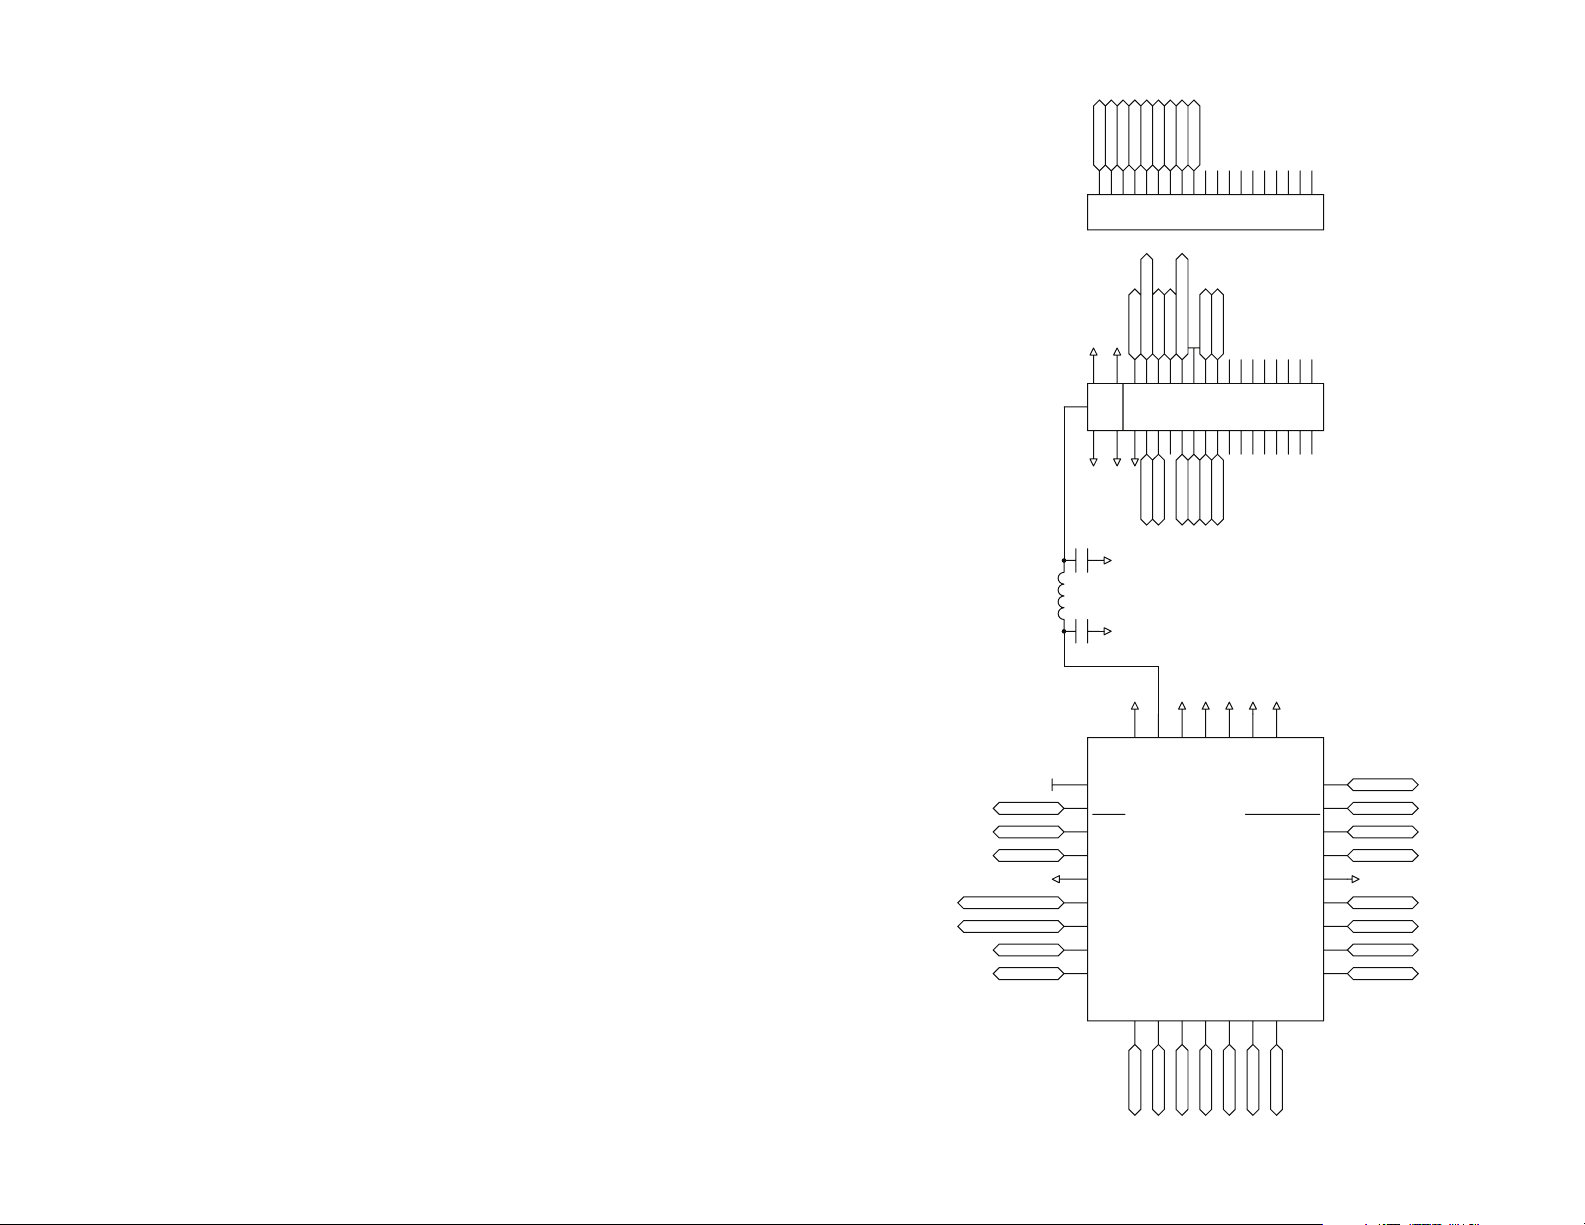
Carrier Board Schematic
S0S1S2S3S4S5S6
38394041424344454647484950515253545556
GND
GND
MODE_IND
ACK_OUT
S7PAIR
VCC
CMD_DATA_IN
CMD_DATA_OUT
LATCH_EN
ACK_EN
C1
The bits in a received packet represented by the 0xFF in the mask must
match exactly or be all ‘1’s in order for the message to be accepted. In this
case, the low byte of the received UDESTID must match the last byte of the
local USRCID or be 0xFF in order for the received packet to be accepted.
Since all modules will accept a 0xFF, this is the network broadcast address.
The HumPRCTM Join Process automatically sets the lower byte UDESTID
to 0xFF, so all modules broadcast to the entire network. This means all
modules can control all other modules in the network. This is limited by the
status line input / output configurations as a line set as an input cannot be
activated. Only lines set as outputs can be activated.
For more information on the addressing modes and join process, please
see RG-00105, the HumPROTM Series Addressing Mode Reference Guide
and RG-00107, The HumPROTM Series Join Process Reference Guide.
1
23
45
67
89
10 11
12 13
14 15
16 17
18 19
20 21
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
J1
Carrier Interconnect
NC1
GND
GND
GND
VCC
GND
PAIR
GND
GND
20
GND
RESET
LNA_EN
PA_EN
ACK_EN
PDN
RESET
GND
19
18
ANT
GND
CMD_DATA_OUT
CMD_DATA_IN
LNA_EN
GND
17
GND
TR1
PA_EN
GND
GND
GND16GND15GND
HUM-***-PRC
GND
14
LATCH_EN
13
POWER_DOWN
12
C1
11
C0
10
GND
9
S0
8
S1
7
S2
6
S3
5
GND
X3
DNP
X1
1.2pF
X2 5.3nH
21
VCC
RESETPDN
22
LNA_EN
23
PA_EN
24
25
GND
CMD_DATA_OUT
26
CMD_DATA_IN
27
ACK_EN
28
PAIR
29
C1
C0
GND
S0
S1
S2
S3
LATCH_EN
MODE_IND30ACK_OUT31GND
MODE_IND
Figure 38: HumPRCTM Series Transceiver Carrier Board Module Schematic
– –
30 31
32
NC1
ACK_OUT
– –
S53S4
S7
S6
1
S7 C0
4
2
S4
S5
S6
Page 19
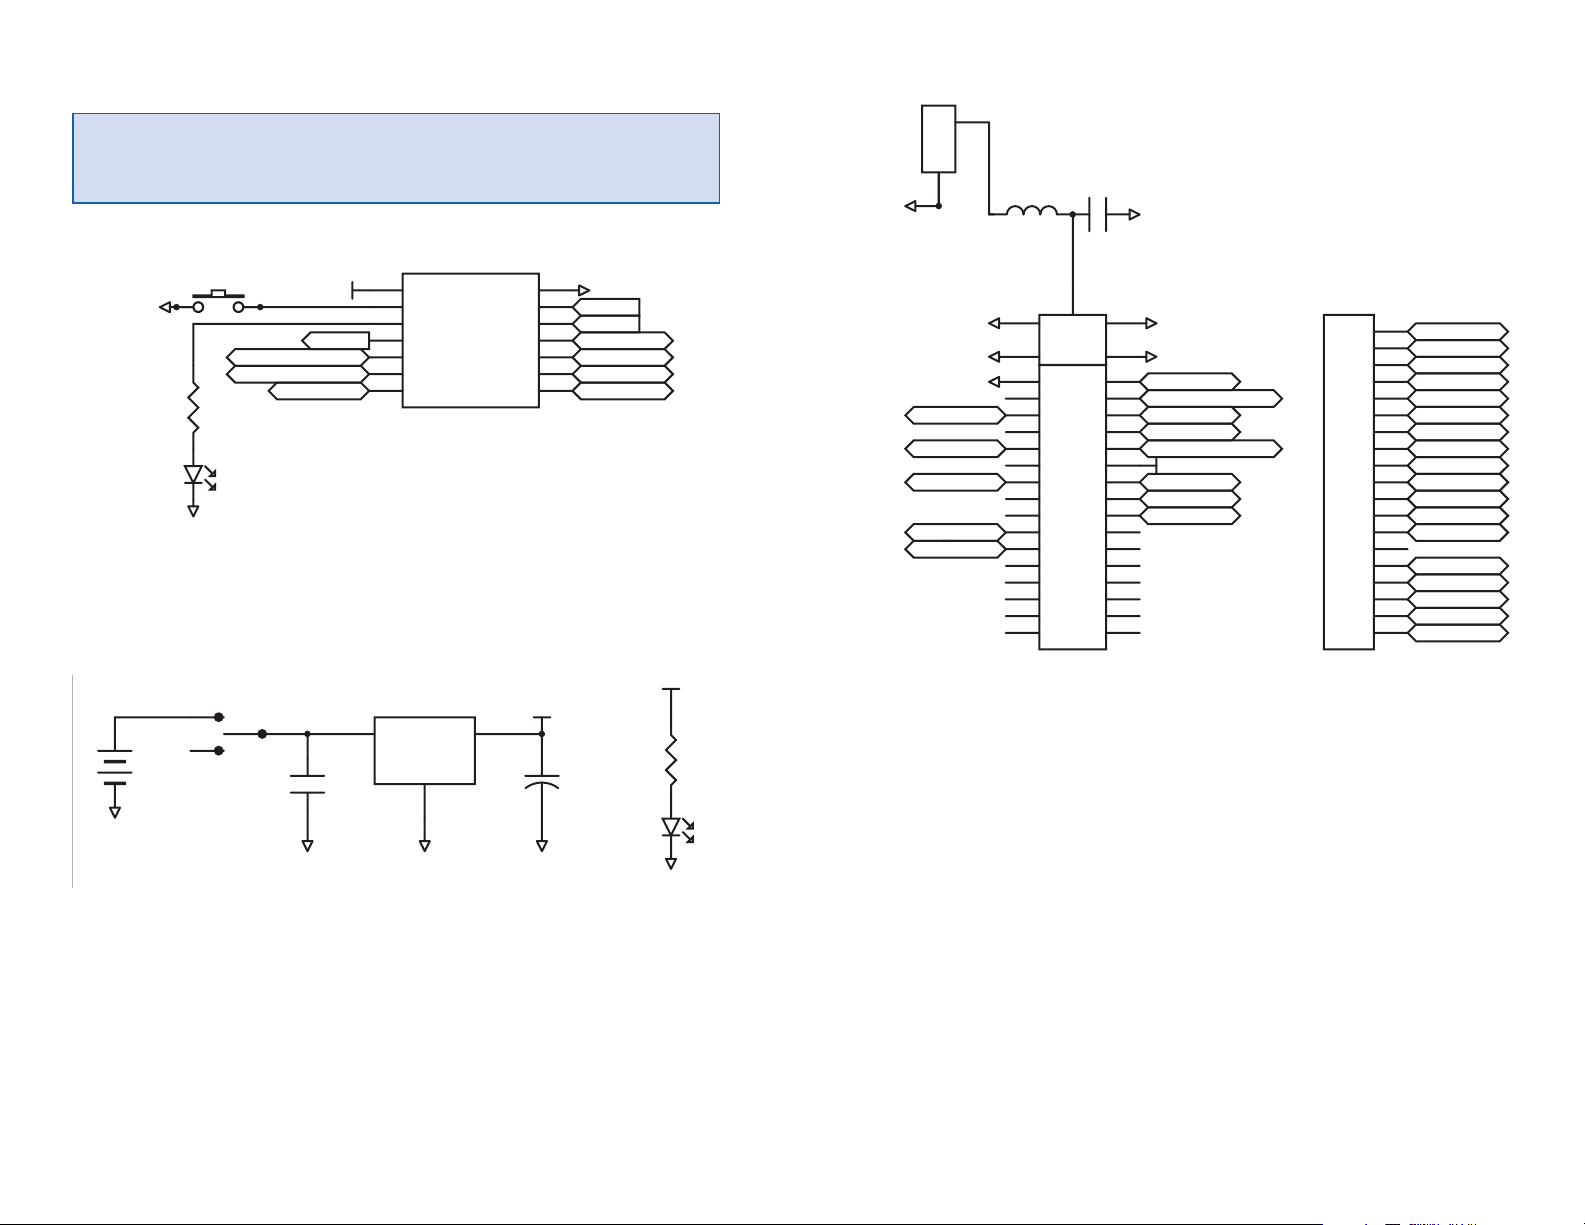
Remote Control Demo Board Schematic
RF
1
GND
2-5
ANT1
CONREVSMA002
PAIR
MODE_IND
CONFIRM
LATCH_EN
D0
D1
D2
D3
D4
D5
ACK_EN
PDN
CMD_DATA_IN
CMD_DATA_OUT
D6
D7
SER_I/O
C0
C1
SEND
CRT_LRN
GND
GND
VCC
GNDGND
GND
GND
1
23
45
67
89
10 11
12 13
14 15
16 17
18 19
20 21
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
J1
Carrier Interconnect Female
LVL_ADJ IDENTITY
GND
X2
DNP
X1
1.8nH
ED_SEL
SEL_TIMER
D8
D9
D_CFG
A_CFG_0
A_CFG_1
BAUD_0
YC
RF MODULE AREA
MICROCONTROLLER AREA
VCC
RF
1
GND
2-5
ANT1
CONREVSMA002
GND
GND
X2
DNP
X1
1.8nH
POWER SUPPLY AREA
RF MODULE AREA
RF MODULE AREA
Note: The Remote Control Demo boards are designed to accept carrier
boards for multiple module families. Some circuitry is not applicable for
some modules.
Figure 39: Remote Control Demo Board Microcontroller Area Schematic
GND
RESTORE
S9
GND
B1
CMD_DATA_OUT
CMD_DATA_IN
R14
330
D7
GND
RESTORE COMPLETE GREEN
SW1
SPDT
U2
1
C1
0.47uF
1
VDD
2
RA5
3
RA4
4
MCLR
5
RC5
6
RC4
7
RC3
PIC16F1824
U1
Vin
GND
Vout
GND
2
VCC GND
MCLR
IDENTIT
GND
GND
ICSPDAT
ICSPCLK
RA2
RC0
RC1
RC2
3
VCC
GND
14
13
12
11
10
9
8
+
100uF
PGD
PGC
SER_I/O
PIC A/B
MODE_IND
RT_LRN
C2
R2
330
D1
POWER GREEN
GND
CONREVSMA002
ANT1
1
RF
GND
GND
2-5
GNDGND
GND
GND
PDN
PAIR
LVL_ADJ IDENTITY
SER_I/O
ED_SEL
X1
1.8nH
X2
GND
DNP
1
23
45
67
89
10 11
12 13
14 15
16 17
18 19
20 21
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
J1
Carrier Interconnect Female
GND
MODE_IND
CMD_DATA_IN
LATCH_EN
ACK_EN
CMD_DATA_OUT
VCC
C0
C1
SEND
Figure 41: Remote Control Demo Board RF Carrier Area Schematic
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
D0
D1
D2
D3
D4
D5
D6
D7
CONFIRM
BAUD_0
SEL_TIMER
CRT_LRN
D8
D9
D_CFG
A_CFG_0
A_CFG_1
Figure 40: Remote Control Demo Board Power Supply Area Schematic
– –
32 33
– –
Page 20
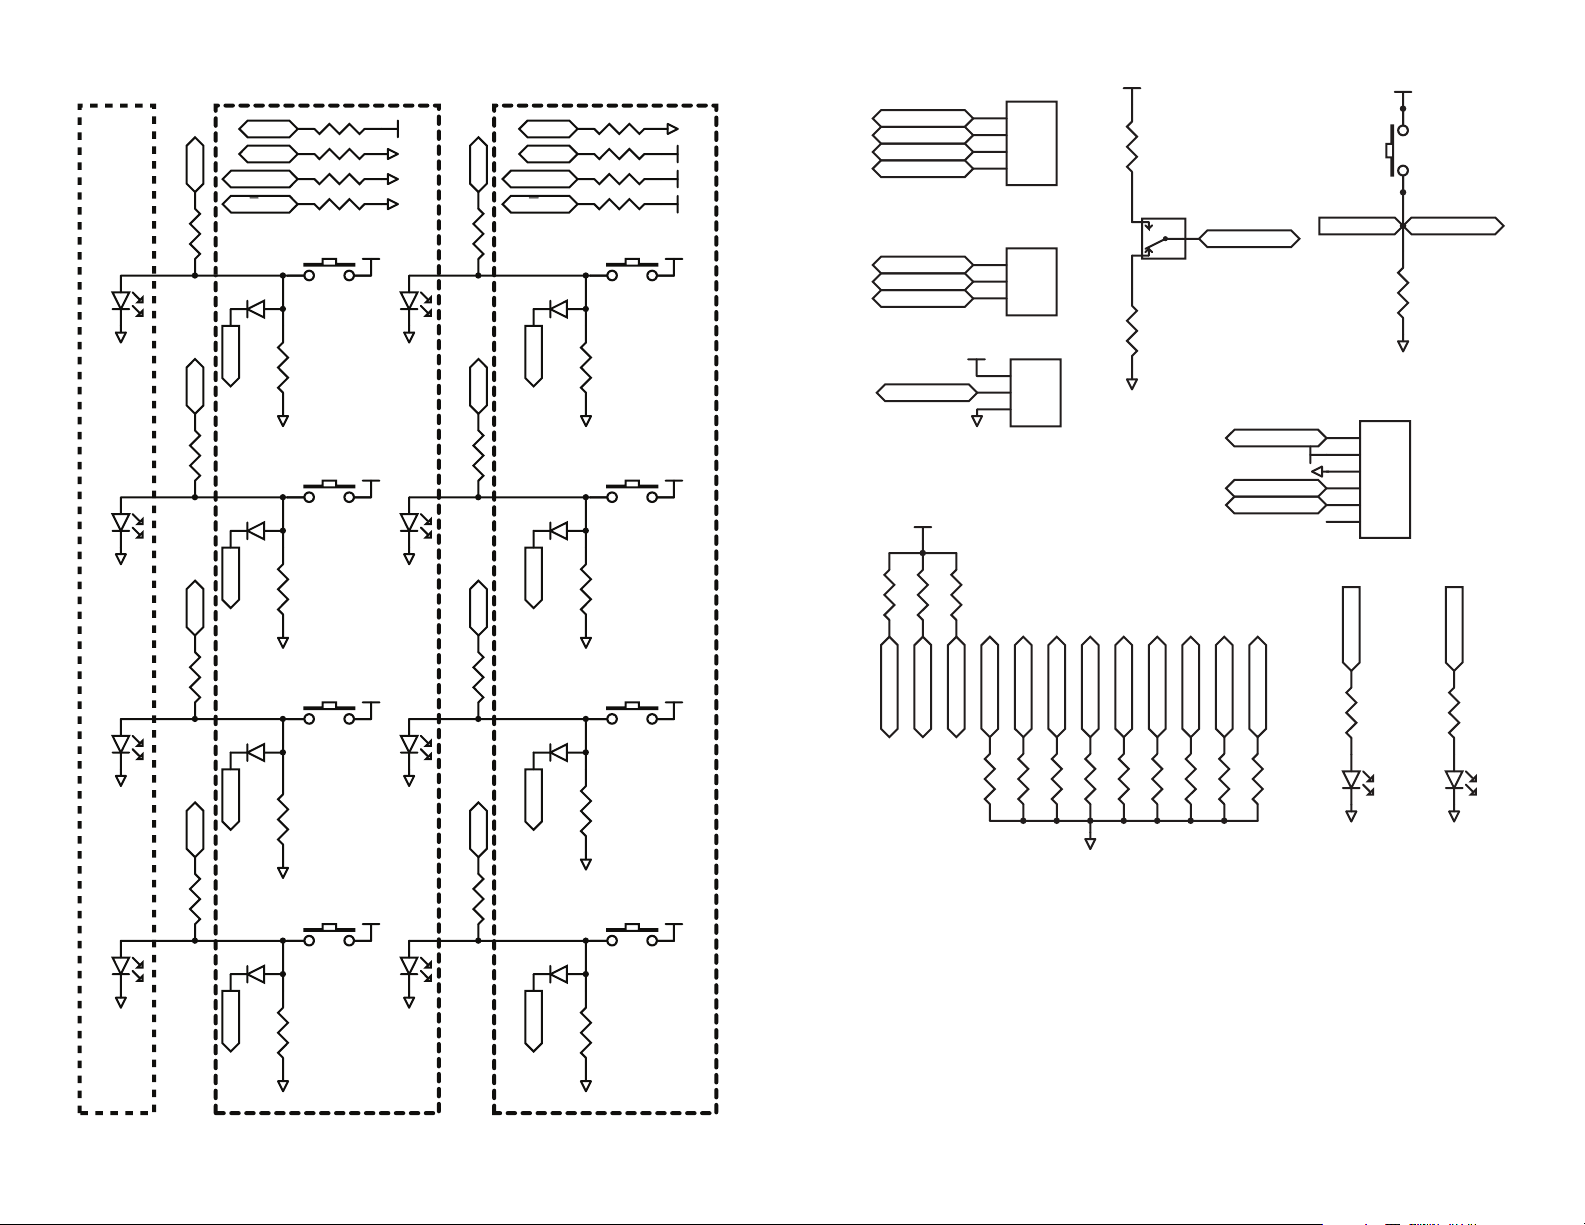
1
2
3
P2
Header 3
D4
D5
D6
1
2
3
4
P1
Header 4
D0
D1
D2
D3
GND
R2
330
VCC
D1
POWER GREEN
MODE_IND
GND
R3
330
D2
MODE_IND BLUE
CONFIRM
GND
R27
330
D20
CONFIRM RED
GND
SW1
SPDT
GND
VCC
B1
GND
Vin
1
GND
2
Vout
3
U1
C1
0.47uF
GND
+
C2
100uF
R36
0
R33
0
VCC
GND
SW2
LVL_ADJ
ACK_EN
R32 0
VCC
R34 10K
BAUD_0
IDENTITY
SEL_TIMER
SEND
LATCH_EN
PDN
R8 0
R38 10K
R37 10K
R35 10K
R9 10K
D8
D9
R41 10K
R42 10K
D_CFG
A_CGF_0
A_CFG_1
R6 10K
R5 10K
R4 10K
GND
VCC
S8
PAIR
R1
10K
PAIR CRT_LRN
REMOTE CONTROL AREA
POWER SUPPLY AREA
MISC CIRCUITS
1
2
3
P3
Header 3
D7
VCC
GND
1
2
3
4
J2
MCLR
PGD
5
6
PGC
VCC
GND
A Board B Board A Board
GND
R2
330
VCC
D1
POWER GREEN
RF
1
GND
2-5
ANT1
CONREVSMA002
PAIR
MODE_IND
CONFIRM
LATCH_EN
D0
D1
D2
D3
D4
D5
ACK_EN
PDN
CMD_DATA_IN
CMD_DATA_OUT
D6
D7
SER_I/O
C0
C1
SEND
CRT_LRN
GND
GND
VCC
GNDGND
GND
GND
1
23
45
67
89
10 11
12 13
14 15
16 17
18 19
20 21
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
J1
Carrier Interconnect Female
LVL_ADJ IDENTITY
GND
X2
DNP
X1
1.8nH
ED_SEL
SEL_TIMER
D8
D9
D_CFG
A_CFG_0
A_CFG_1
BAUD_0
GND
SW1
SPDT
GND
VCC
B1
GND
Vin
1
GND
2
Vout
3
U1
C1
0.47uF
GND
+
C2
100uF
VDD
1
RA5
2
RA4
3
MCLR
4
RC5
5
RC4
6
RC3
7
RC2
8
RC1
9
RC0
10
RA2
11
ICSPCLK
12
ICSPDAT
13
GND
14
U2
PIC16F1824
VCC GND
PGD
PGC
MCLR
CMD_DATA_IN
CMD_DATA_OUT
IDENTITYCRT_LRN
MODE_IND
GND
SER_I/O
R14
330
GND
S9
RESTORE
D7
RESTORE COMPLETE GREEN
PIC A/B
VCC
POWER SUPPLY AREA
RF MODULE AREA
MISC CIRCUITS
MICROCONTROLLER AREA
R30 0 ohm
D5
D10
D14
D18
GND
GND
GND
GND
C0
C1 GND
D0
PIC A/B
ED_SEL
R12
330
D3
R10
10K
SEND
D1
GND
R17
330
D8
R15
SEND
10K
D2
R21
GND
330
D12
R19
SEND
10K
D3
R25
GND
330
D16
R23
SEND
10K
GND
R31 0 ohm
R39 0 ohm
R7 10K
VCCS0
VCCS1
VCCS2
VCCS3
D19
D15
D11
D6
VCC
GND
GND
GND
GND
GND
GND
D7
R26
330
R22
330
R18
330
R13
330
PIC A/B
ED_SEL
D6
D5
D4
R28 0 ohm
C0
R29 0 ohm
C1
R40 0 ohm
R43 10K
D17
R24
SEND
10K
GND
D13
R20
SEND
10K
GND
D9
R16
SEND
10K
GND
D4
R11
SEND
10K
GND
P1
GND
VCC
VCC
VCC
VCCS7
VCCS6
VCCS5
VCCS4
D0
D1
D2
D3
Figure 43: Remote Control Demo Board Miscellaneous Circuits Schematic
D6
D5
D4
D7
VCC
R4 10K
R32 0
R8 0
PDN
ACK_EN
1
2
3
4
Header 4
P2
Header 3
VCC
GND
A_CGF_0
A_CFG_1
R5 10K
1
2
3
P3
1
2
3
Header 3
D_CFG
R6 10K
LATCH_EN
R35 10K
R9 10K
SEND
GND
R33
0
SW2
R36
0
GND
BAUD_0
SEL_TIMER
R37 10K
R38 10K
IDENTITY
R34 10K
LVL_ADJ
MCLR
VCC
GND
PGD
PGC
D8
D9
R41 10K
R42 10K
VCC
S8
PAIR
PAIR CRT_LRN
R1
10K
GND
J2
1
2
3
4
5
6
MODE_IND
R3
330
D2
CONFIRM RED
GND
MODE_IND BLUE
GND
CONFIRM
R27
330
D20
Figure 42: Remote Control Demo Board Remote Control Area Schematic
– –
34 35
– –
Page 21
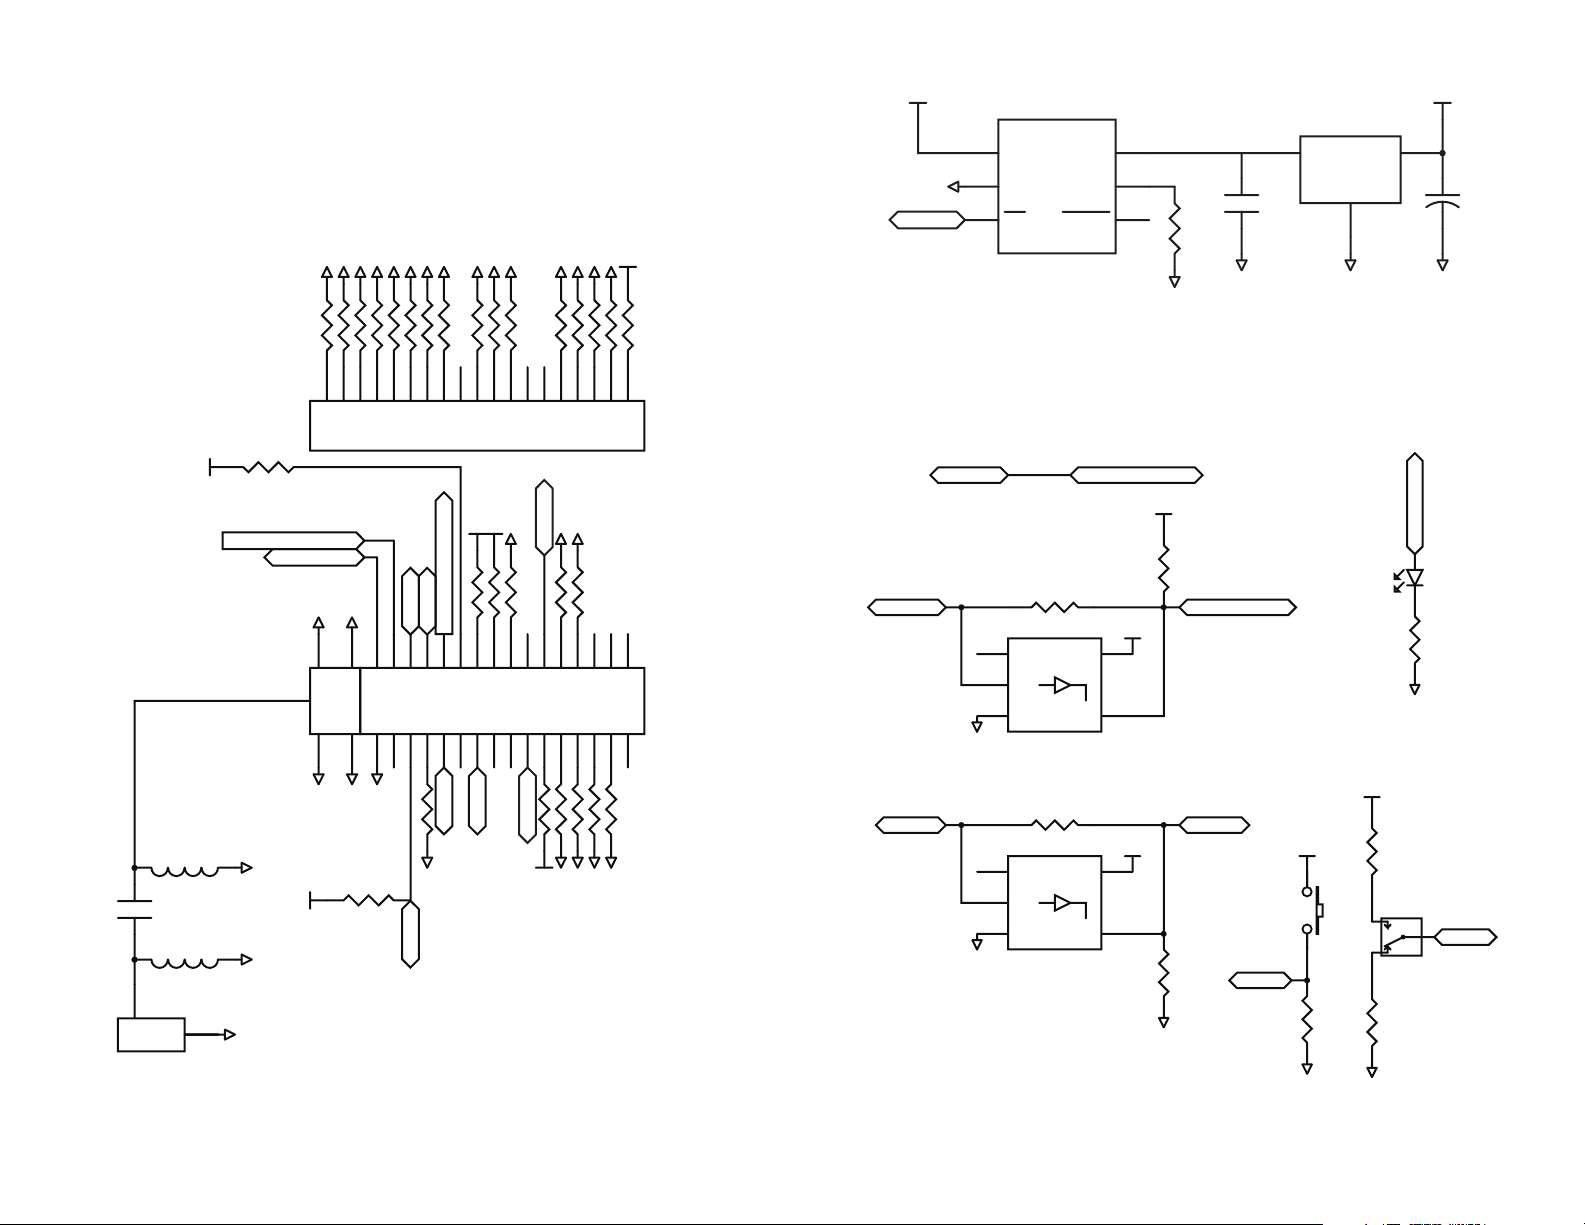
Programming Dock Board Schematic
R9 10k
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
R35 10k
R34 10k
R33 10k
R32 10k
R30 10k
R28 10k
R22 10k
R21 10k
R18 10k
R15 10k
R14 10k
R13 10k
R12 10k
R10 10k
GND
R38 10k
VCC
GND
+
C8
100uF
VCC
GND
Vin
1
GND
2
Vout
3
U4
LM3940IMP 3.3V
C9
0.47uF
GND
IN
1
GND
2
EN3FAULT
4
ILIM
5
OUT
6
U3
TPS2552
GND
5VUSB
GND
R11
53.6k
PWREN#
SIGNAL ROUTING
R9 10k
GND
38394041424344454647484950515253545556
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
R35 10k
R34 10k
R33 10k
R32 10k
R30 10k
R28 10k
R22 10k
R21 10k
R18 10k
R15 10k
R14 10k
R13 10k
R12 10k
R10 10k
GND
R38 10k
VCC
R16
10k
VCC
VCC
R1
1 Ohm
MODE_IND
CMD_DATA_IN
CMD_DATA_OUT
GND
GND
GNDGND
GND
1
23
45
67
89
10 11
12 13
14 15
16 17
18 19
20 21
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
J2
Carrier Interconnect
R29 10k
GND
GND
VCC
VCC
R27 10k
R25 10k
R1910k
R3110k
VCC
PAIR
GND
R2610k
GND
R3710k
GND
R3910k
GND
R4310k
R44 10k
GND
R45 10k
GND
RF
1
GND
2-5
ANT1
GND
GND
X1
1nH
X3
DNP
GND
X2
DNP
LADJ
nPDN nCMD
nCTS
GPIO2
GPIO1
R1
1 Ohm
VCC
GND
GND
R13 10k
R12 10k
R10 10k
38394041424344454647484950515253545556
CMD_DATA_IN
MODE_IND
GND
1
23
45
GND
GND
GND
R15 10k
R14 10k
67
89
GND
GND
GND
R9 10k
R22 10k
R21 10k
R18 10k
CMD_DATA_OUT
R25 10k
nCTS
10 11
12 13
14 15
16 17
5VUSB
GND
GND
GND
GND
R32 10k
R30 10k
R28 10k
R33 10k
GND
GND
R34 10k
VCC
GND
R38 10k
R35 10k
GND
PWREN#
U3
TPS2552
1
IN
2
GND
EN3FAULT
Vout
3
VCC
+
GND
C8
100uF
U4
LM3940IMP 3.3V
GND
1
C9
0.47uF
Vin
GND
2
GND
6
OUT
5
ILIM
R11
4
53.6k
GND
Figure 45: Programming Dock Board Power Supply Area Schematic
CMD_DATA_OUTRXD
GND
VCC
VCC
R27 10k
18 19
20 21
R29 10k
GND
GND
GPIO1
R44 10k
R45 10k
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
J2
Carrier Interconnect
GND
Buffer Bypass DNP
R48 DNP
U1
1
2
VCC
NC
IN
GND3OUT
VCC
R46
10k
VCC
5
4
CMD_DATA_INTXD
MODE_IND
D4
MODE_IND BLUE
R8
330 ohm
GND
GND
GND
GNDGND
X3
DNP
X1
ANT1
GND
1nH
X2
DNP
1
RF
2-5
GND
VCC
GND
GND
R16
10k
nPDN nCMD
Figure 44: Programming Dock Board RF Carrier Area Schematic
– –
36 37
Buffer Bypass DNP
PAIR
VCC
PAIR
GND
U5
1
2
R49 DNP
VCC
NC
IN
GND3OUT
VCC
5
4
GND
R17
10k
– –
LADJ
PAIR
R1910k
GND
GPIO2
R3110k
VCC
R2610k
R3710k
R3910k
R4310k
GND
GND
GND
GND
RTS nCMD
Figure 46: Programming Dock Board Signal Routing Schematic
GND
VCC
R40
0 ohm
S2
R24
10k
SW1
LADJ
R41
0 ohm
GND
Page 22
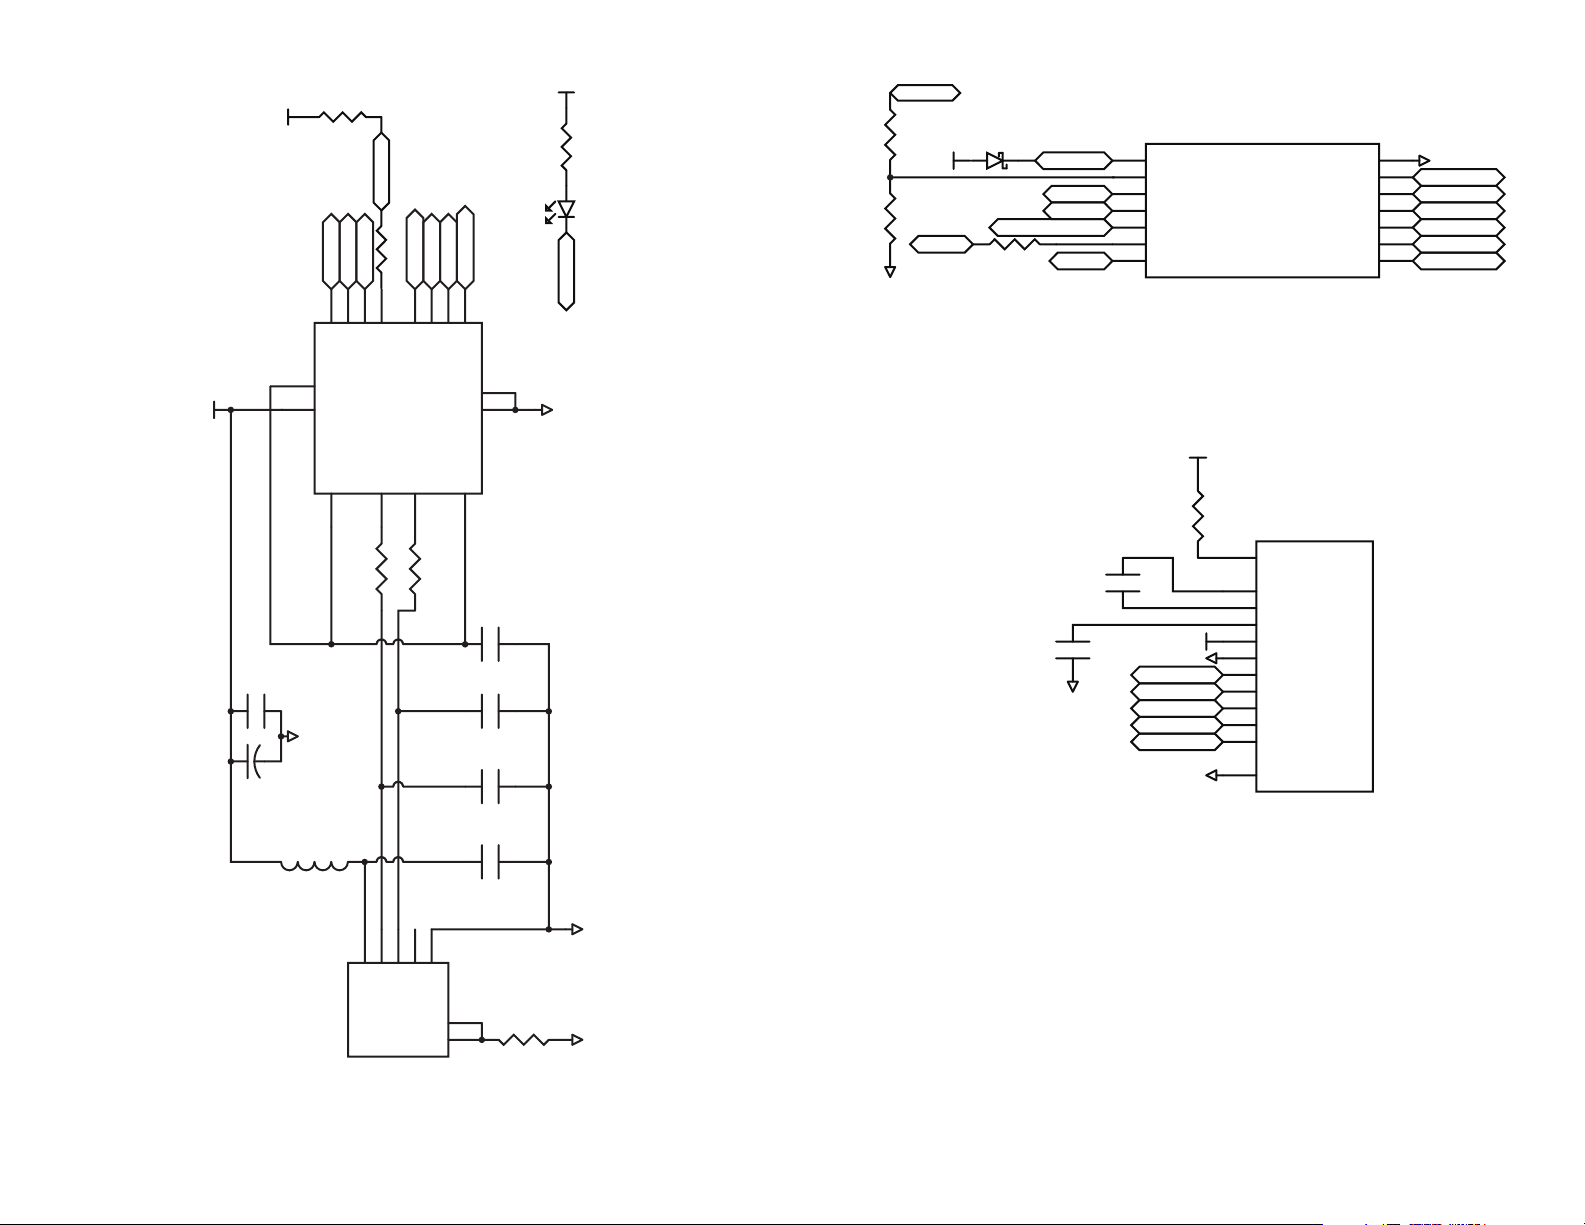
GND
+
C8
100uF
VCC
GND
Vin
1
GND
2
Vout
3
U4
LM3940IMP 3.3V
C9
0.47uF
GND
IN
1
GND
2
EN3FAULT
4
ILIM
5
OUT
6
U3
TPS2552
GND
5VUSB
GND
R11
53.6k
PWREN#
USB AREA POWER SUPPLY AREA RF MODULE CARRIER AREA
SIGNAL ROUTING
R20
R17
10k
GND
NC
1
IN
2
GND3OUT
4
VCC
5
U5
VCC
GND
R49 DNP
Buffer Bypass DNP
RTS nCMD
CMD_DATA_OUTRXD
NC
1
IN
2
GND3OUT
4
VCC
5
U1
VCC
GND
R46
10k
VCC
R48 DNP
CMD_DATA_INTXD
Buffer Bypass DNP
GND
MODE_IND
R8
330 ohm
D4
MODE_IND BLUE
R24
10k
S2
VCC
PAIR
PAIR
GND
R41
0 ohm
R40
0 ohm
VCC
GND
SW1
LADJ
USB AREA POWER SUPPLY AREA RF MODULE CARRIER AREA
MICROCONTROLLER AREA
GND
+
C1
C6
47pF
C2
0.1uF
VCC
12
VCCIO
3
3V3OUT
10
GND
5
GND
13
USBDM9USBDP
8
RESET#
11
TXD
1
RXD
4
RTS#2CTS#
6
CBUS015CBUS114CBUS27CBUS3
16
U2
FT230X
C5
47pF
PWREN#
C7
0.1uF
GND
5VUSB
RTS
R2 27
R3 27
TXD
RXD
nCTS
VCC
R20
10k
R47 DNP
GPIO2
RXTXLED
D1
R5
330 ohm
ORANGE
RXTXLED
VCC
GPIO1
10k
VCC
RTS
TXD
RXD
1
4
TXD
RXD
RTS#2CTS#
3
12
5VUSB
VCCIO
VCC
3V3OUT
U2
FT230X
10
C2
0.1uF
4.7uF
GND
L1
600R/1.3A
+
C1
6
R2 27
nCTS
R47 DNP
USBDM9USBDP
8
PWREN#
GPIO2
GPIO1
16
CBUS015CBUS114CBUS27CBUS3
11
R3 27
RXTXLED
GND
GND
RESET#
C7
C6
C5
13
5
0.1uF
47pF
47pF
VCC
R5
330 ohm
D1
ORANGE
RXTXLED
GND
nPDN
R36
DNP
VCC GND
R23
DNP
RXD
GND
D2
CMD_DATA_IN
R42 DNP
VCCP
GPIO1
PGM
CSB RS
1
2
3
4
5
6
7
U8
VDC
RA5
RA4
MCLR
RC5
RC4
RC3
PIC16F1825-I/ST
Figure 48: Programming Dock Board Microcontroller Area Schematic
GND
C13
1uF
C14
1uF
SI
SCL
CSB
RS
RST
VCC
VCC
GND
GND
R6
0 Ohm
LCD1
1
LED+
2
C1-
3
C1+
4
VOUT
5
VCC
6
GND
7
SI
8
SCL
9
CSB
10
RS
11
RST
12
LED-
2x16 LCD
GND
ICSPDAT
ICSPCLK
RA2
RC0
RC1
RC2
14
13
12
11
10
9
8
PGD
PGC
RST
SCL
SI
1
2
5V
J1
Micro USB
Figure 47: Programming Dock Board USB Area Schematic
– –
– –
DAT-
3NC4
DAT+
5
GND
GSHD
GSHD
C4
0.01uF
6
R4
0
7
GND
GND
38 39
Page 23
RF
1
GND
2-5
ANT1
CONREVSMA001
GND
GND
GND
X1
0 Ohm
X3
DNP
GND
GND
X2
DNP
+
GND
C1
4.7uF
C3
0.01uF
L1
600R/1.3A
GND
C5
47pF
R4
0
C2
0.1uF
VCC
12
VCCIO
3
3V3OUT
10
GND5GND
13
USBDM
9
USBDP
8
RESET
11
TXD
1
RXD
4
RTS
2
CTS
6
CBUS0
15
CBUS1
14
CBUS2
7
CBUS3
16
U6
FT230X
C4
47pF
C6
0.1uF
GND
5V
1
DAT-
2
DAT+
3
NC
4
GSHD
6
GSHD
7
GND
5
RTS
CTS
R1 27
R2 27
5VUSB
EN
BCD Charger
TXD
RXD
SW1
SW2
9
15
CMD_DATA_IN
CMD_DATA_OUT
NC
1
IN
2
GND3OUT
4
VCC
5
U3
VCC
GND
R25
DNP
VCC
R27 DNP
NC
1
IN
2
GND
3
OUT
4
VCC
5
U4
R33
DNP
GND
VCC
R36 DNP
PROTOTYPE
AREA
GND BUS
1
TXD
RXD
RTS
CTS
VCC BUS
1
TP2
GND GND
TP1
VCC
29
30
31
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
123
4
J6
100mil Header
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
J5
100mil Header
GND
VCC
R10 DNP
VCC
R19 DNP
GND
VCC
R11 DNP
GND
R14 DNP
GND
R17 0 ohm
VCC
R12 DNP
GND
R26 DNP
R23 DNP
GND
R21 DNP
GND
R15
DNP
VCC
R18
DNP
GND
R13 DNP
R8 DNP
R16 DNP
GND
R20 DNP
GND
R28 DNP
GND
R29 DNP
VCC
R30 DNP
GND
R31 DNP
GND
C9
0.1uF
GND
VCC
6
R6 DNP
GND
OUT
IN
GND
GND
+
C7
10uF
THERM
4
1
2
3
U5
THERM
RF
1
GND
2-5
ANT1
CONREVSMA001
GND
GND
GND
R24
330
5VUSB
D2
POWER (GREEN)
D3
OVER CURRENT (RED)
R22
330
VCC
FAULT
U2
R5
10k
GND
5VUSB
GND
C8
0.47uF
FAULT
IN1GND2EN
3
FAULT
4
ILIM
5
OUT
6
TPS2553
SW3
5VUSB
EN
FAULT
GND1
2
J3
100mil Header
Battery Input
D1
GND
R7
53.6k
R9
53.6k
GND
Q1
R3
10k
BCD Charger
VCC
PROTOTYPE
AREA
GND BUS
1
VCC BUS
1
TP2
GND GND
TP1
VCC
293031
789101112131415161718192021222324252627
28
12345678910111213141516171819202122232425
26
J5
100mil Header
GND
VCC
R10 DNP
VCC
R19 DNP
GND
VCC
R11 DNP
GND
R14 DNP
GND
R17 0 ohm
VCC
R12 DNP
GND
R26 DNP
R23 DNP
GND
R21 DNP
GND
R15
DNP
VCC
R18
DNP
GND
R13 DNP
R8 DNP
R16 DNP
GND
R20 DNP
GND
R28 DNP
GND
R29 DNP
VCC
R30 DNP
GND
R31 DNP
GND
C9
0.1uF
GND
VCC
6
R6 DNP
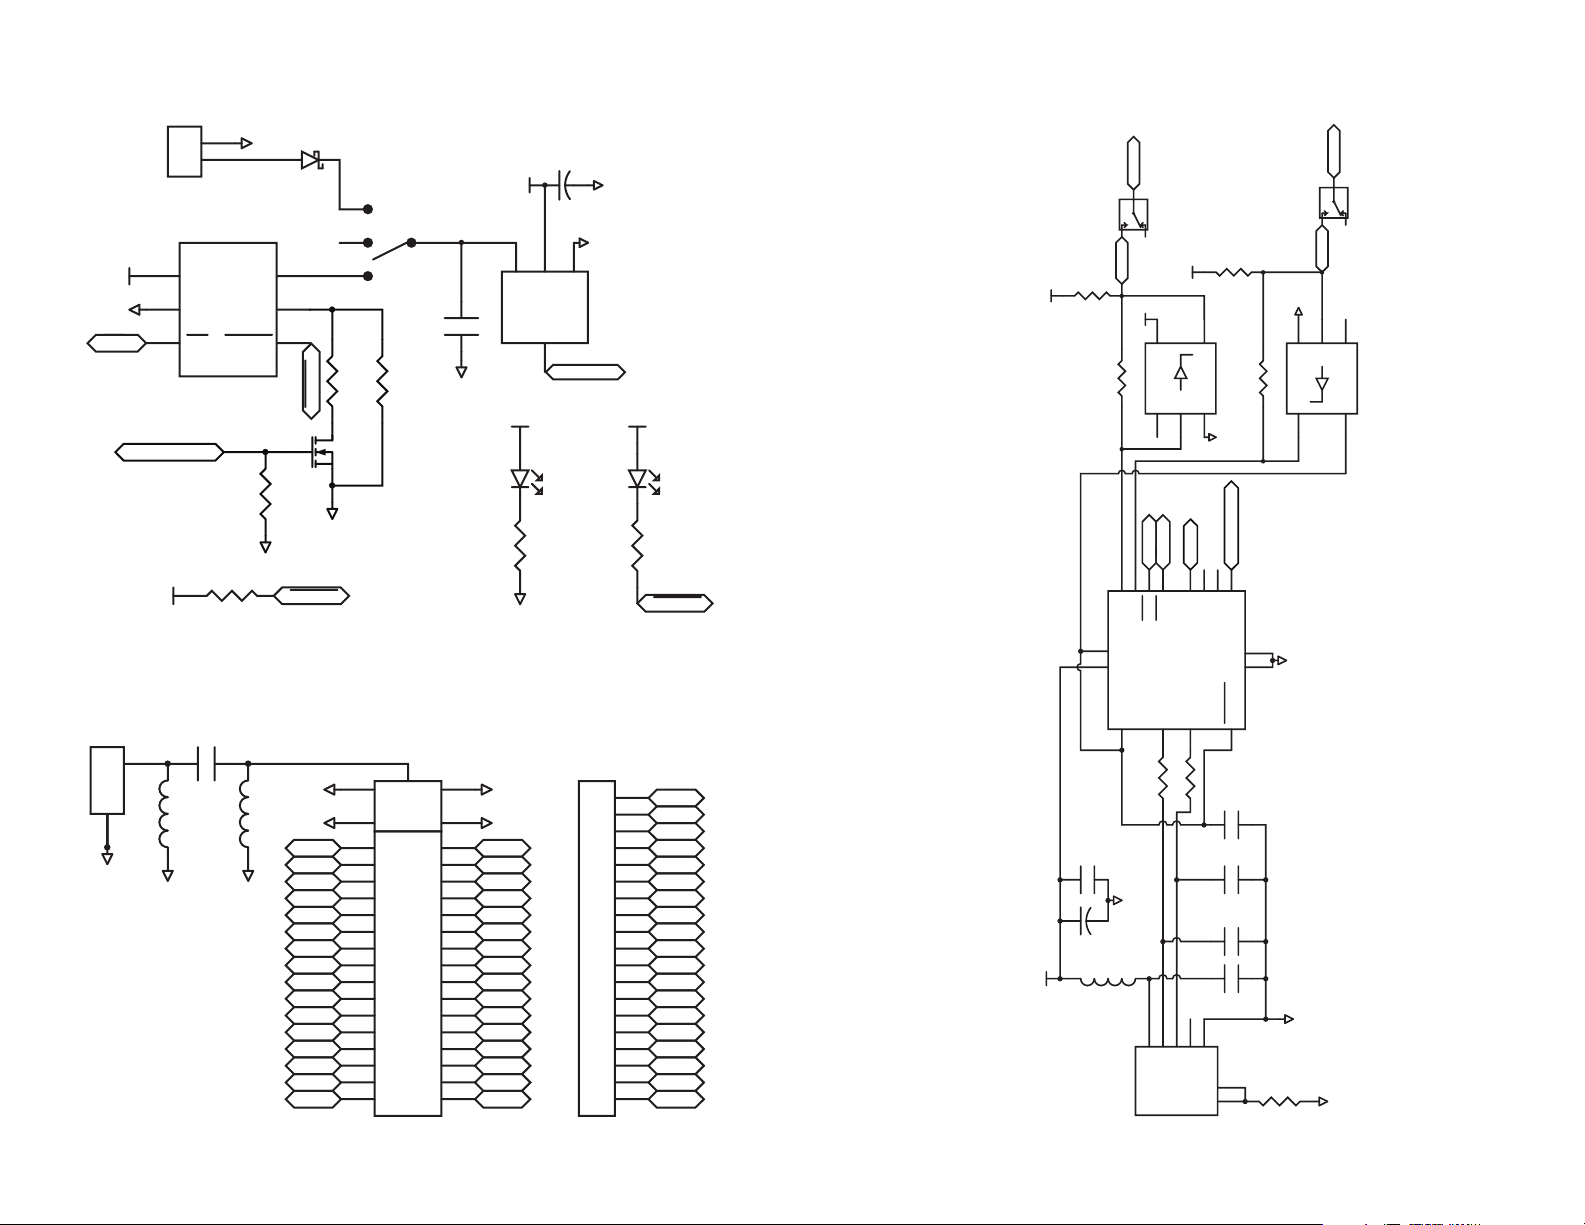
Prototype Board Schematic
GND
EN
100mil Header
Battery Input
1
2
5VUSB
J3
2
U2
IN
GND
EN3FAULT
OUT
ILIM
GND1
TPS2553
BCD Charger
R3
10k
GND
5VUSB
R5
10k
Figure 49: Prototype Board Power Supply Area Schematic
CONREVSMA001
ANT1
RF
GND
2-5
GND
1
GND
X2
DNP
X1
0 Ohm
X3
DNP
GND
Figure 50: Prototype Board RF Carrier Area Schematic
6
5
4
D1
FAULT
GND
SW3
0.47uF
R7
53.6kR953.6k
Q1
C8
GND
VCC
VCC
3
IN
THERM
D2
R22
C7
10uF
2
OUT
4
+
1
GND
THERM
GND
GND
U5
5VUSB
330
POWER (GREEN)
FAULT
GND
OVER CURRENT (RED)
J2
Carrier Interconnect Female
GND
GND
6
89
10 11
12 13
14 15
16 17
18 19
20 21
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
1
23
45
67
89
10 11
12 13
14 15
16 17
18 19
20 21
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
– –
40 41
GND
GND
7
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
D3
R24
330
FAULT
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
Figure 51: Prototype Board USB Area Schematic
VCC
5VUSB
+
R25
DNP
3
12
U6
C2
0.1uF
C1
4.7uF
L1
600R/1.3A
CMD_DATA_IN
SW1
R27 DNP
1
10
9
CMD_DATA_OUT
15
TXD
TXD
VCC
VCC
4
5
U3
4
RXD
VCC
VCC
NC1IN2GND
RTS
CTS
6
RTS2CTS
CBUS015CBUS114CBUS27CBUS3
VCCIO
OUT
3
EN
R33
DNP
R36 DNP
GND
BCD Charger
16
FT230X
GND
GND
5
U4
13
SW2
RXD
GND
1IN2
3
GND
OUT4VCC
5
GND
NC
3V3OUT
USBDM9USBDP8RESET
GND
J1 Micro USB
R1 27
1
2
5V
DAT-
– –
11
R2 27
C6
0.1uF
GND
GSHD
GSHD
C5
47pF
C4
47pF
C3
0.01uF
6
R4
7
3NC4
5
DAT+
GND
0
GND
Page 24
GND
J3
GND
GND
R32DNP
R34DNP
323334
123456789
J4
100mil Header
C9
CTS
RTS
RXD
TXD
4
3
2
1
J6
100mil Header
VCC BUS
GND
0.1uF
1
VCC
GND
GND
GND
R40DNP
R39DNP
R38DNP
R35DNP
39404142434445
38
37
36
35
PROTOTYPE
TP1
12345678910111213141516171819202122232425
J5
100mil Header
789101112131415161718192021222324252627
6
R10 DNP
R11 DNP
R12 DNP
R8 DNP
R6 DNP
VCC
VCC
GND
GND
GND
VCC
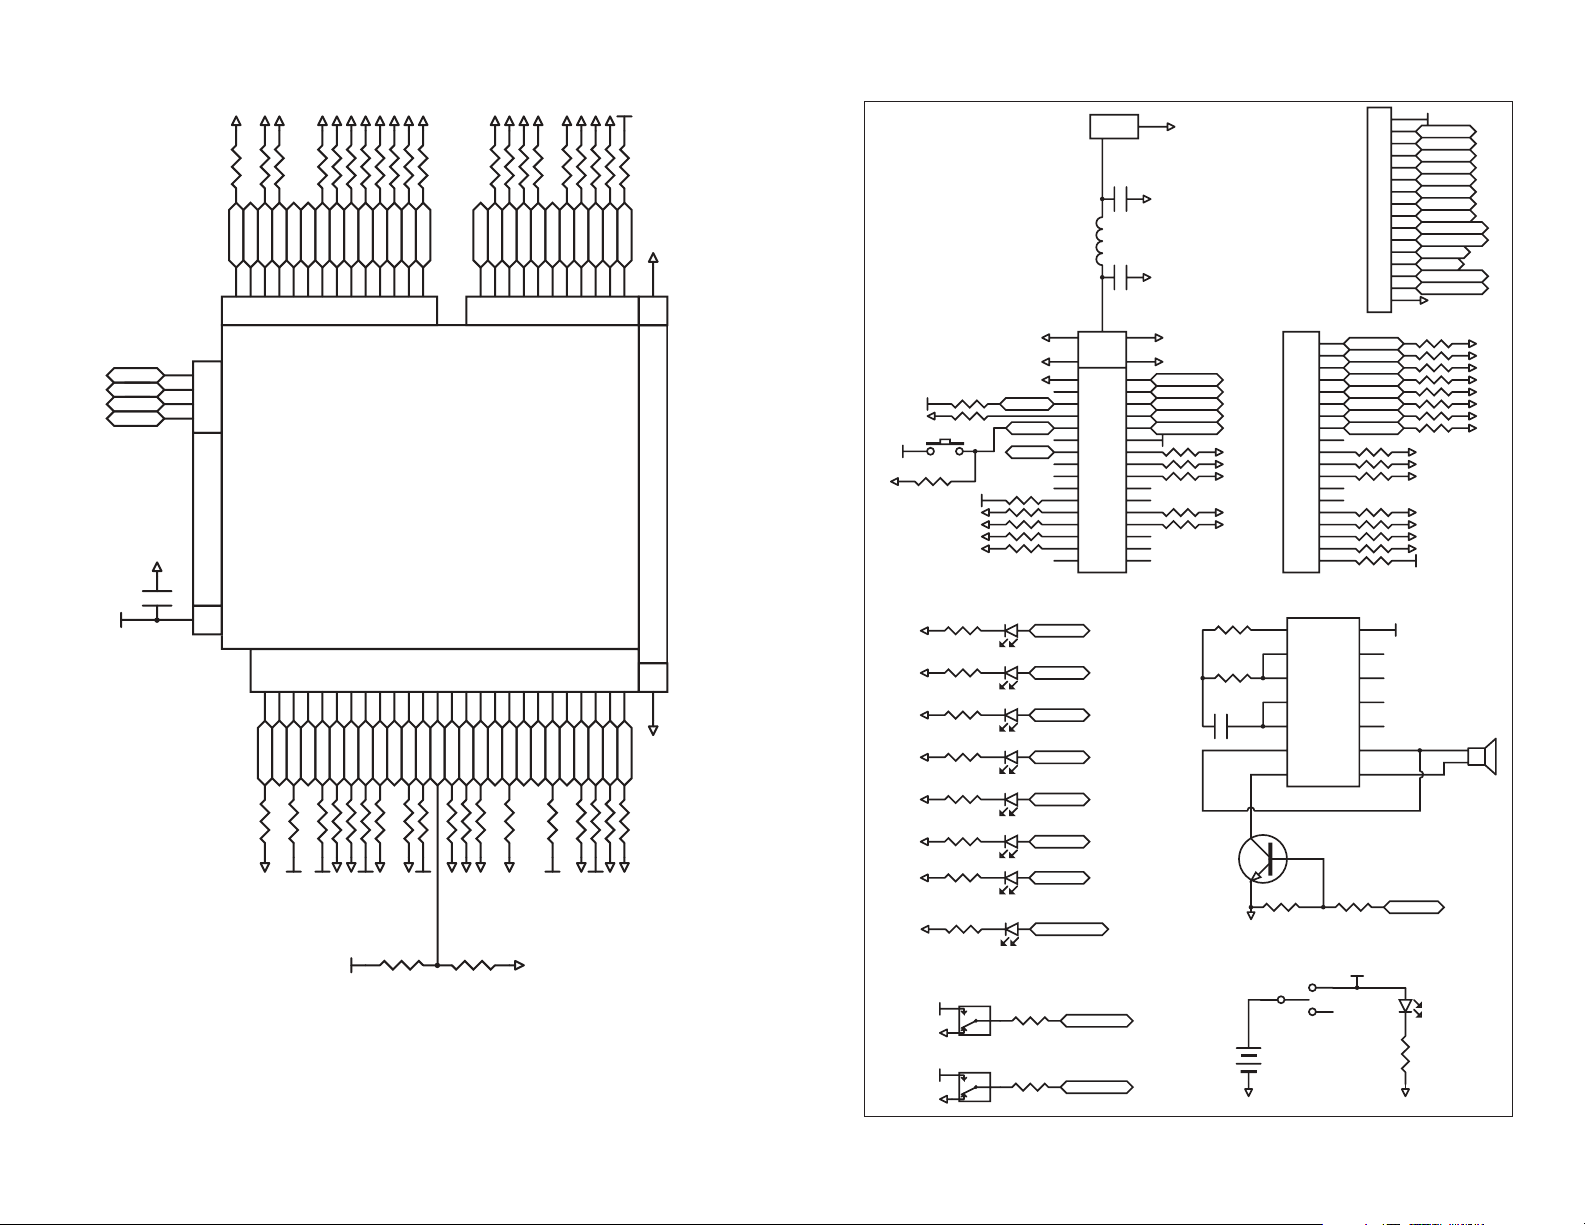
Figure 52: Prototype Board Prototype Area Schematic
GND
GND
GND
GND
GND
R45DNP
R44DNP
R43DNP
R42DNP
R41DNP
1011121314
AREA
R14 DNP
R17 0 ohm
R13 DNP
R16 DNP
VCC
VCC
GND
GND
R15
DNP
GND
GND
GND
GND
R50DNP
R47DNP
R48DNP
R49DNP
4647484950515253545556
123456789
J7
100mil Header
R19 DNP
GND
R20 DNP
GND
R18
R21 DNP
GND
DNP
R23 DNP
R26 DNP
GND
GND
GND
R52DNP
VCC
R53DNP
R28 DNP
GND
GND
R54DNP
293031
28
R29 DNP
VCC
GND
GND
R55DNP
10
R30 DNP
GND
R56DNP
R31 DNP
VCC
11
26
GND
HumPRCTM Series Evaluation Board Schematic
ANT1 CONREVSMA001
GND
RF
1
X2
0 Ohm
1
TP3
GNDGND
GND
B1
R20 10k
VCC
R21 10k
GND
R24 10k
GND
R27 10k
GND
R29 10k
GND
D1
D2
D3
D4
D5
D6
D7
D8
MODE_IND BLUE
SW1
R43 10k
SW-SMT-SPDT
SW2
R44 10k
SW-SMT-SPDT
GND
nPDN LATCH_EN
PAIR
NC
R42 10k
VCC
R10 10k
GND
PAIR
VCC
GND
R37
10k
GND BUS
R34
GND
620 ohm
R35
1
TP2
GND GND
GND
GND
GND
GND
GND
GND
GND
VCC
GND
VCC
GND
620 ohm
R36
620 ohm
R38
620 ohm
R39
620 ohm
R40
620 ohm
R41
620 ohm
R2
330 ohm
S1
S2
S3
S4
S5
S6
S7
MODE_IND
LATCH_EN
ACK_EN
23
1
45
67
89
10 11
12 13
14 15
16 17
18 19
20 21
22 23
24 25
26 27
28 29
30 31
32 33
34 35
36 37
GND
2-5
X1
GND
DNP
X3
GND
DNP
GND
MODE_IND
CD_IN
ACK_EN
CD_OUT
VCC
R14 10k
R16 10k
R18 10k
R22 10k
R25 10k
Carrier Interconnect
0.01uF
38
39
40
41
42
43
44
45
46
1
2
3
4
5
6
7
GND
S1
Power Switch
BAT1
2x AAA
47
48
49
50
51
52
53
54
55
56
U1
A
A`
B
B`
C
C`
GND
CHP-HEXINV-SSOP
Q1
2N2222
GND
GND
GND
GND
GND
J2
R8
100k
R13
10k
C1
GND
VCC
R33 2.2KR32 10K
F
F`
E
E`
D
D`
VCC
R17 10k
R19 10k
R23 10k
R26 10k
R28 10k
R30 10k
R31 10k
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
HEADER 16
S0
S1
S2
S3
S4
S5
S6
S7
R1510k
14
13
12
11
10
9
8
VCC
S0
S1
S2
S3
S4
S5
S6
S7
ACK_EN
LATCH_EN
nPDN
PAIR
CD_IN
CD_OUT
GND
R3 10k
R4 10k
R5 10k
R6 10k
R7 10k
R9 10k
R11 10k
R12 10k
GND
GND
GND
GND
GND
GND
GND
VCC
VCC
S0
Power LED Green
D9
R1
620 ohm
GND
GND
GND
GND
GND
GND
GND
GND
GND
BZ1
BUZZER
Figure 53: HumPRCTM Series Evaluation Board Schematic
– –
42 43
– –
Page 25
Linx Technologies
159 Ort Lane
Merlin, OR, US 97532
Phone: +1 541 471 6256
Fax: +1 541 471 6251
www.linxtechnologies.com
Disclaimer
Linx Technologies is continually striving to improve the quality and function of its products. For this reason, we
reserve the right to make changes to our products without notice. The information contained in this Data Guide
is believed to be accurate as of the time of publication. Specifications are based on representative lot samples.
Values may vary from lot-to-lot and are not guaranteed. “Typical” parameters can and do vary over lots and
application. Linx Technologies makes no guarantee, warranty, or representation regarding the suitability of any
product for use in any specific application. It is the customer’s responsibility to verify the suitability of the part for
the intended application. NO LINX PRODUCT IS INTENDED FOR USE IN ANY APPLICATION WHERE THE SAFETY
OF LIFE OR PROPERTY IS AT RISK.
Linx Technologies DISCLAIMS ALL WARRANTIES OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR
PURPOSE. IN NO EVENT SHALL LINX TECHNOLOGIES BE LIABLE FOR ANY OF CUSTOMER’S INCIDENTAL OR
CONSEQUENTIAL DAMAGES ARISING IN ANY WAY FROM ANY DEFECTIVE OR NON-CONFORMING PRODUCTS
OR FOR ANY OTHER BREACH OF CONTRACT BY LINX TECHNOLOGIES. The limitations on Linx Technologies’
liability are applicable to any and all claims or theories of recovery asserted by Customer, including, without
limitation, breach of contract, breach of warranty, strict liability, or negligence. Customer assumes all liability
(including, without limitation, liability for injury to person or property, economic loss, or business interruption) for
all claims, including claims from third parties, arising from the use of the Products. The Customer will indemnify,
defend, protect, and hold harmless Linx Technologies and its officers, employees, subsidiaries, affiliates,
distributors, and representatives from and against all claims, damages, actions, suits, proceedings, demands,
assessments, adjustments, costs, and expenses incurred by Linx Technologies as a result of or arising from any
Products sold by Linx Technologies to Customer. Under no conditions will Linx Technologies be responsible for
losses arising from the use or failure of the device in any application, other than the repair, replacement, or refund
limited to the original product purchase price. Devices described in this publication may contain proprietary,
patented, or copyrighted techniques, components, or materials. Under no circumstances shall any user be
conveyed any license or right to the use or ownership of such items.
©2017 Linx Technologies. All rights reserved.
The stylized Linx logo, Wireless Made Simple, WiSE, CipherLinx and the stylized CL logo are trademarks of Linx Technologies.
Page 26
Mouser Electronics
Authorized Distributor
Click to View Pricing, Inventory, Delivery & Lifecycle Information:
Linx Technologies:
MDEV-900-PRC MDEV-868-PRC
 Loading...