

Page 1
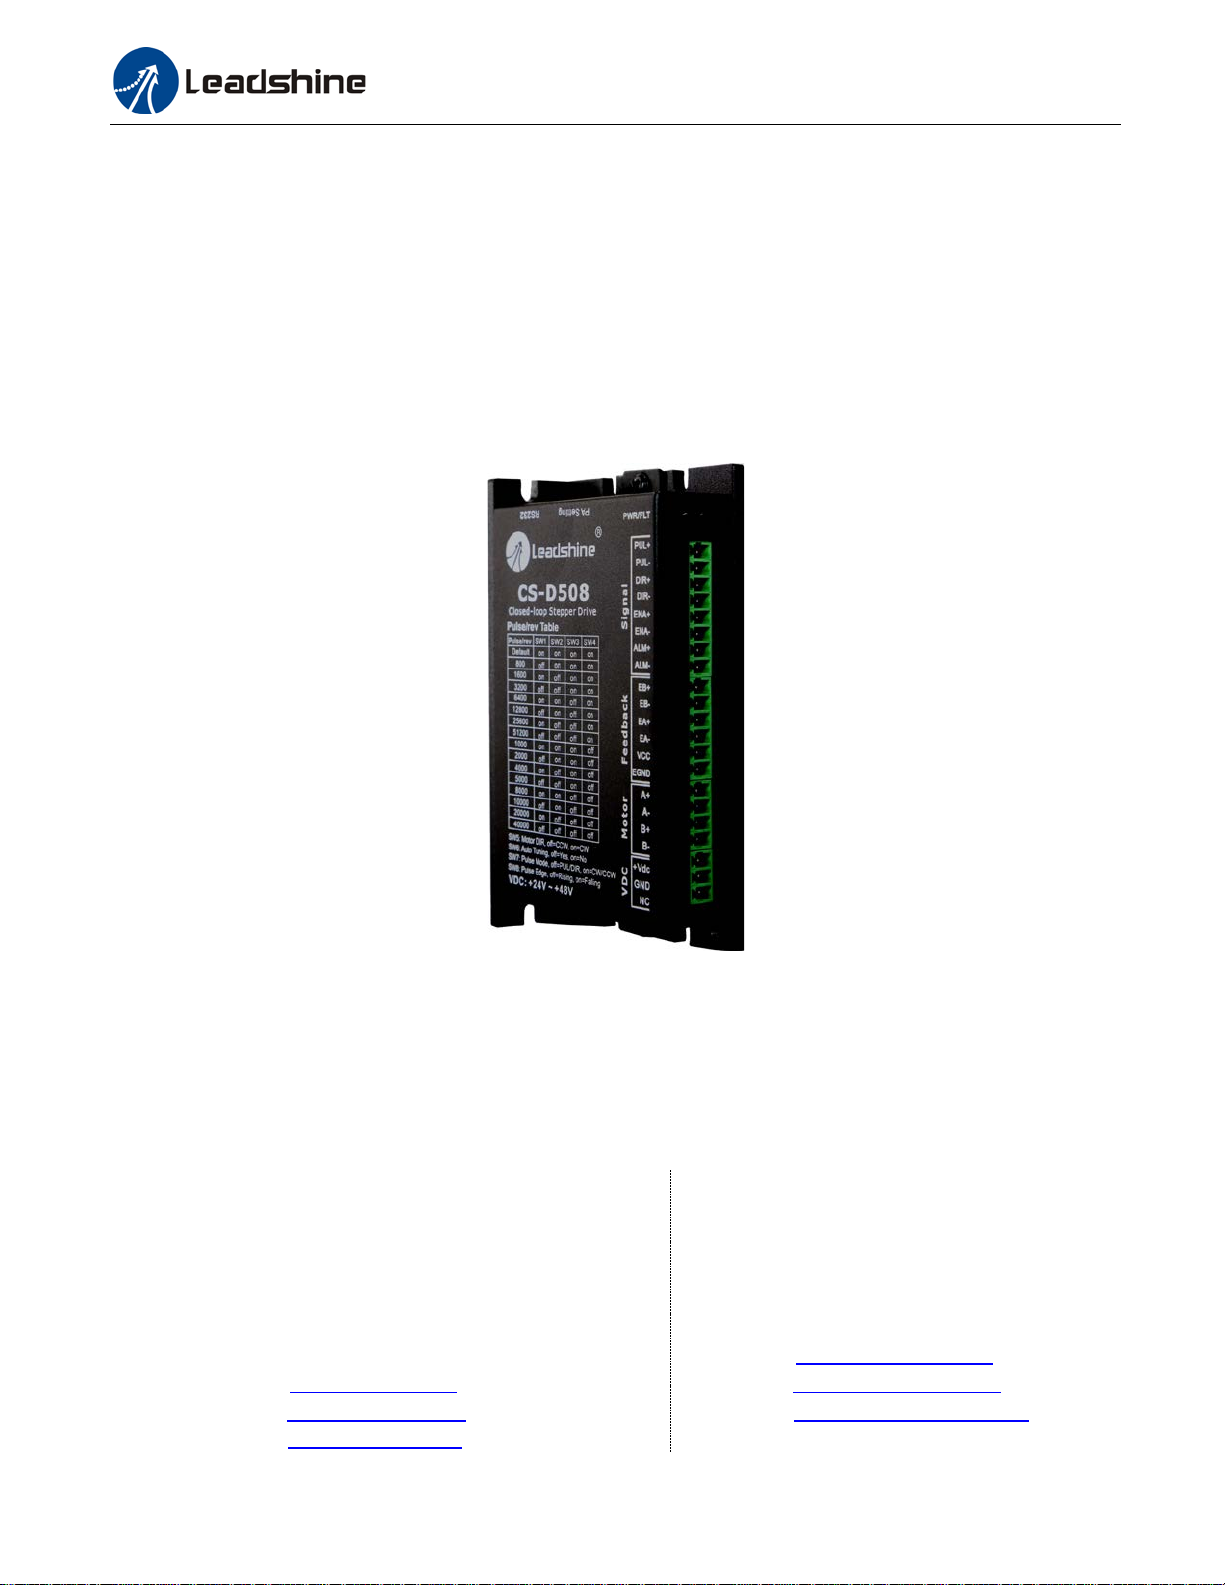
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
Support: [email protected]
User Manual
CS-D508
Closed Loop Stepper Drive
Revision 3.1
©2018 Leadshine Technology Co., Ltd.
Leadshine Technology Co., Ltd (Headquarters)
Address: Floor 11, Block A3, iPark
1001 Xueyuan Avenue
Shenzhen, Guangdong 518055
China
Tel: 86-400-885-5521
Fax: 86-755-2640-2718
Leadshine America, Inc.
Address: 26050 Towne Centre Dr.
Foothill Ranch, CA 926
USA
Tel: 1-949-608-7270
Fax: 1-949-608-7298
Web: www.leadshineusa.com
Sales: [email protected]
Support: [email protected]
Page 2
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
1.0
September, 2017
Initial Release
3.1
October, 2018
Firmware and PC software update to version 3.1
Notice
Read this manual carefully before any assembling and using. Incorrect handling of products in this manual can result in
injury and damage to persons and machinery. Strictly adhere to the technical information regarding installation
requirements.
This manual is not for use or disclosure outside of Leadshine except under permission. All rights are reserved. No part
of this manual shall be reproduced, stored in retrieval form, or transmitted by any means, electronic, mechanical,
photocopying, recording, or otherwise without approval from Leadshine. While every precaution has been taken in the
preparation of the book, Leadshine assumes no responsibility for errors or omissions. Neither is any liability assumed
for damages resulting from the use of the information contained herein.
This document is proprietary information of Leadshine that is furnished for customer use ONLY. Information in this
document is subject to change without notice and does not represent a commitment on the part of Leadshine.
Therefore, information contained in this manual may be updated from time-to-time due to product improvements, etc.,
and may not conform in every respect to former issues.
Record of Revisions
Revision Date Description of Release
Page 3
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
Table of Cont ent
1. Introduction.................................................................................................................................................................. 1
1.1 Features ................................................................................................................................................................ 1
1.2 Applications ......................................................................................................................................................... 1
2. Specifications ................................................................................................................................................................ 2
2.1 Electrical Specifications ...................................................................................................................................... 2
2.2 Environment ........................................................................................................................................................ 2
2.3 Mechanical Specifications ................................................................................................................................... 3
2.4 Heat Dissipation................................................................................................................................................... 3
3.1 Connector P1 – Control and Digital Output Connections.................................................................................... 4
3.1.1 Pin Assignm ent s of P1 .............................................................................................................................. 4
3.1.2 Typical Control and Fault Output Connections ........................................................................................ 6
3.2 Connector P2 - Encoder Connection.................................................................................................................... 7
3.3 Connector P3 - Motor Connection ....................................................................................................................... 7
3.4 Connector P4 – Power Supply Connection .......................................................................................................... 7
3.5 Connector P5 – RS232 Connection ..................................................................................................................... 8
3.6 LED Light Indication ........................................................................................................................................... 8
4. Motor Selection ............................................................................................................................................................ 8
5. Power Supply Selection ............................................................................................................................................... 8
5.1 Regulated or Unregulated Power Supply ............................................................................................................. 9
5.2 Power Supply Sharing ......................................................................................................................................... 9
5.3 Selecting Supply Voltage ..................................................................................................................................... 9
6. DIP Switch Configurations ......................................................................................................................................... 9
6.1 Microstep Resolution (SW1-SW4) .................................................................................................................... 10
6.2 Other DIP Switch Settings (SW5-SW8) ............................................................................................................ 11
7. T ypical Connection .................................................................................................................................................... 11
Page 4
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
8. Sequence Chart of Control Signals .......................................................................................................................... 11
9. Fault Protections ........................................................................................................................................................ 12
10. Software Configuration ........................................................................................................................................... 13
11. Accessori es ................................................................................................................................................................ 13
12. T r oublesho oting ....................................................................................................................................................... 14
13. Warra nty .................................................................................................................................................................. 16
Appendix A. Leadshine CS-D508 Compatible Stepper Motors .............................................................................. 17
Appendix B. Leadshine CS-D508 Compatible Power Supplies .............................................................................. 18
Appendix C. Powering a Third Party Motor with CS-D508 ................................................................................... 19
Page 5
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
1. Introd uction
Leadshine CS-D508 is a closed loop stepper drive designed to solve the loss of step problem in open loop stepper
control systems, thus increase system reliability at minimal cost increase. It implements advanced control algorithm of
Leadshine based on its tens of years’ experience in stepper and servo controls. The CS-D508 is highly reliable and
affordable and performs excellent in many industrial applications such as CNC, medical, electronics, packaging...
The CS-D508 can power 2-phase NEMA 17, 23, and 24 stepper motors with incremental encoders. Compared with
traditional open loop stepper systems, a CS-D508 adopted closed loop step system can eliminate potential loss of step,
make real-time position error correction, and do not need torque reservation (100% torque implementation). Also it can
power the driven stepper motor with reduced heating, lower noise, low vibration…
1.1 Features
No loss of step
No torque reservation
No hunting or overshooting
No tuning for easy setup
Capable of powering NEMA 8-34 stepper motors with rotary encoders
Configurable mode for enhanced performance for applications of extra low speed and fast acceleration
Configurable digital output for Fault Output, In Position, or Brake Control
Excellent torque, low noise & vibration, smooth motion
Step & direction or CW/CCW control modes
20-50VDC supply voltage, max 8A output current
Max 200 KHz input frequency
15 micro step settings of 800-51,200 via DIP switches, or 200-51,200 by software
1.2 Applications
When a CS-D508 closed loop stepper drive is implemented with a compatible stepper motor with encoder, the closed
stepper system can be adopted in many small to median speed applications such as CNC routers, CNC mills, CNC
laser cutters, CNC plasma, lab automation instruments, plotters, medical equipment, electronic equipment, small
packaging machines, etc.
Page | 1
Page 6
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
2. Specifications
2.1 Electrical Specifications
Parameters Min Typical Max Unit
Output Current 0.5 - 8.0(Peak) A
Operating Voltage 20 24, 36, 48 50 VDC
Logic signal current 7 10 16 mA
Pulse input frequency 0 - 200 kHz
Minimal pulse width 2.5 - - μS
Minimal direction setup 5.0 - - μS
Isolation resistance 500 MΩ
2.2 Environment
Cooling Natural Cooling or Forced Cooling
Operating Environment
Storage T emperat ure
Weight Approx. 280 g (9.9 Oz)
Environment
Ambient T em perature
Humidity
Operating T em perature
Vibration
Avoid dust, oil fog and corrosive gases
0°C - 65°C (32°F - 149°F)
40%RH-90%RH
0°C - 50°C (32°F - 122°F)
10-50Hz / 0.15mm
-20°C - 65°C (-4°F - 149°F)
Page | 2
Page 7
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
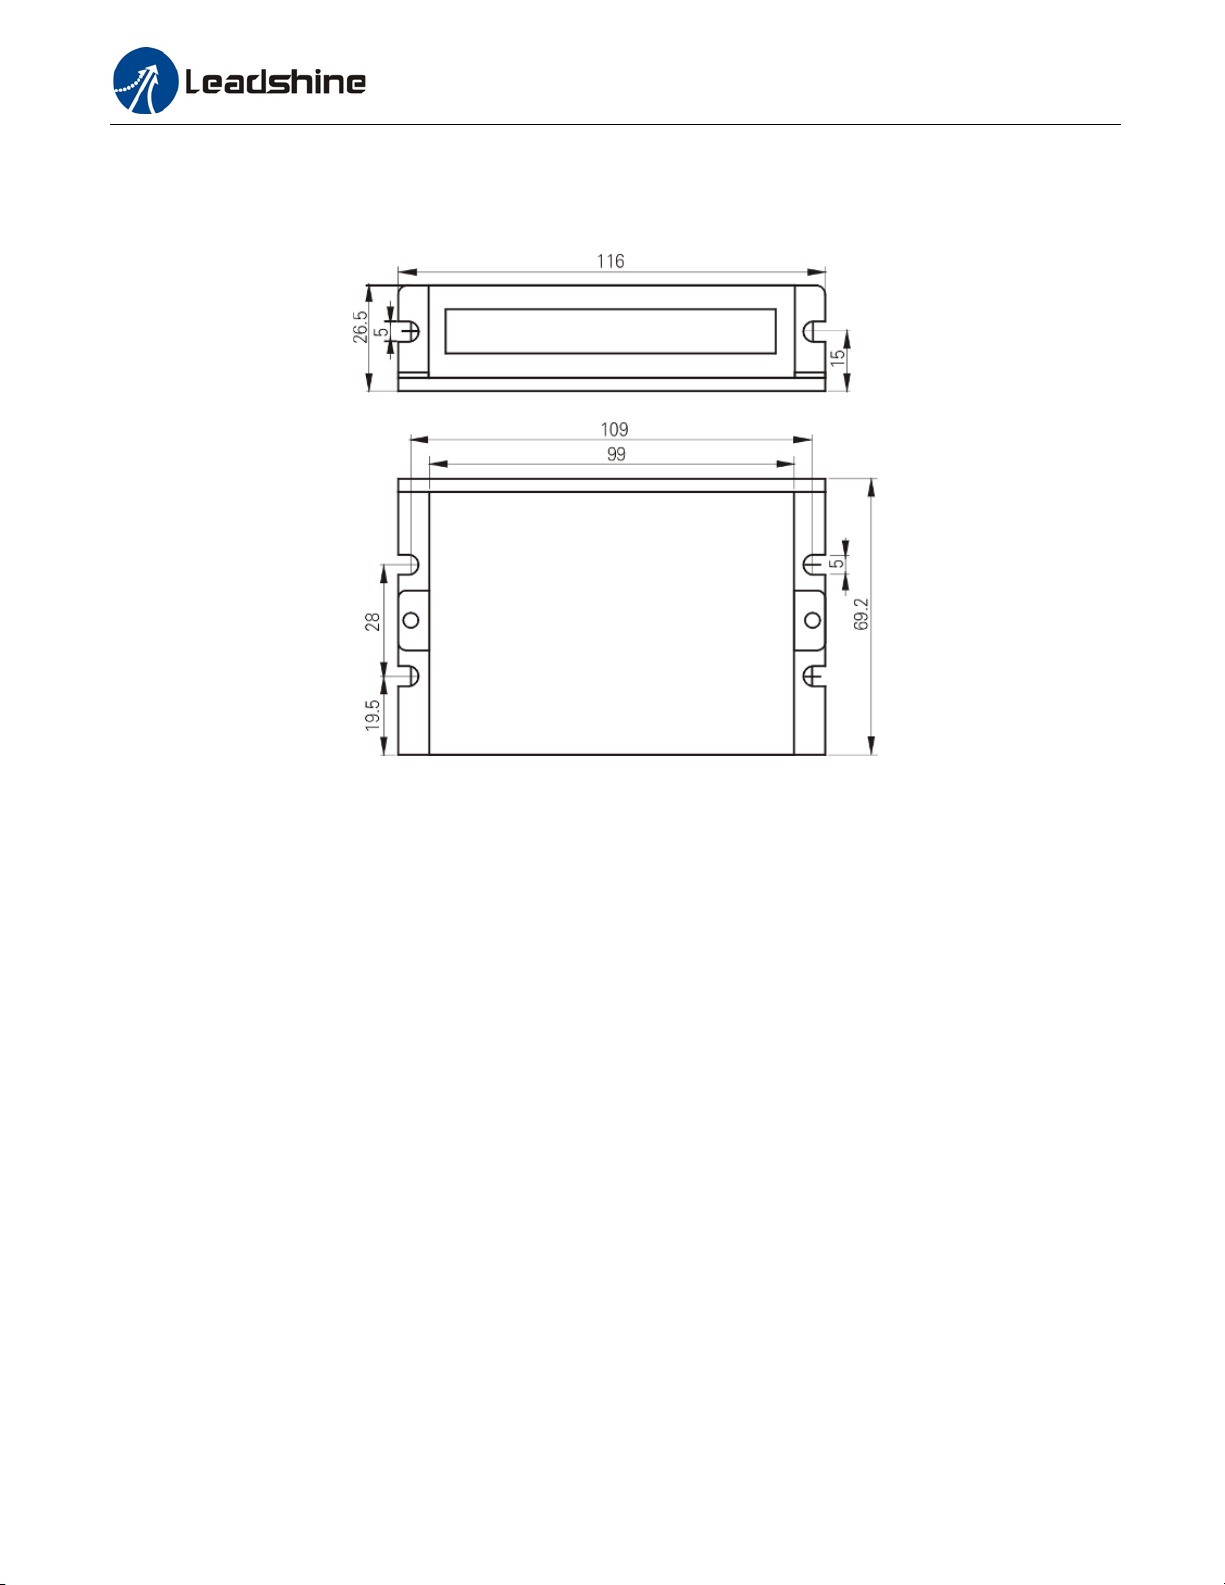
2.3 Mechanical Specifications
(unit: mm [1inch=25.4mm])
Figure 1: Mechanical specifications
2.4 Heat Dissipation
CS-D508 reliable working temperature should be no more than 60℃ (140°F)
It is recommended to mount the drive vertically to maximize heat dissipation. Mount a cooling fan nearby if
necessary.
If multiple CS-D508 drives are installed, it is suggested to keep a minimal 30mm (12 inches) between two of
them.
Page | 3
Page 8
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
3. Connections an d L ED Indi cat i on
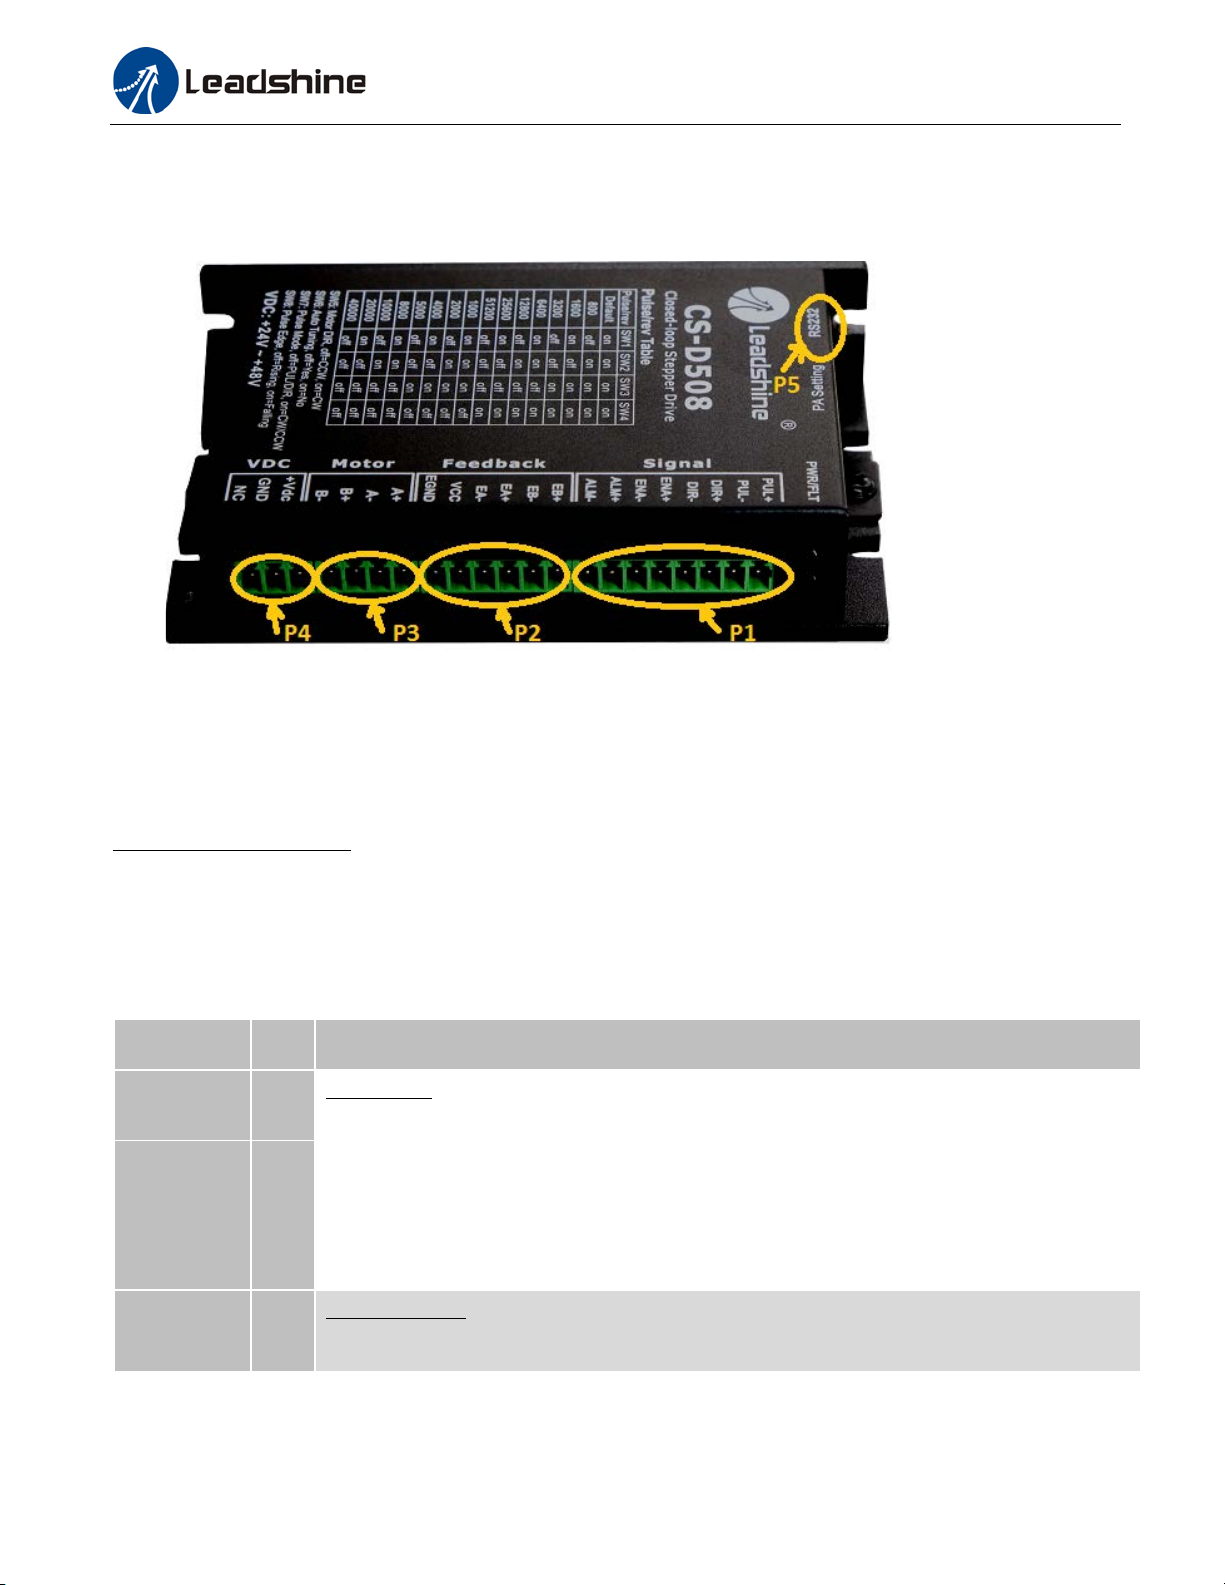
A CS-D508 closed loop stepper drive has 5 connection blocks from P1 to P5 (see figure 2).
Figure 2: CS-D508 connectors
3.1 Connector P1 – Control and Digital Output Connect ions
3.1.1 Pin Assignm ent s of P1
The P1 connector in Figure 2 are used for connections of input control signals and one configurable digital output.
a) Pinout Definitions
There are 3 control signals for pulse, direction, and enable. See the following table for details.
Pin Name I/O Details
PUL+ I
Pulse signal: (1). In single pulse (pulse & direction) control mode, this input represents pulse
signal. A pulse signal is active at the rising or falling voltage edge (set by DIP switch SW8).
(2). In double-pulse (CW/CCW) control mode (set by DIP switch SW7), this signal input
represents clockwise (CW) pulse, and is active at both high voltage level and low voltage level.
PUL- I
(3). 4.5-24V for voltage HIGH, 0-0.5V for voltage LOW (same for DIR and ENA signals). (4).
Pulse width should be set to 2.5μs or longer.
DIR+ I
Direction signal: (1). In single pulse (step & direction) control mode, this signal’s low and high
voltage levels represent the two directions of motor rotation (e.g. clockwise and
Page | 4
Page 9
DIR- I
drive. PNP and Differential control signals are on the contrary, namely Low level for enabling.
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
counterclockwise). (2). In double-pulse (CW & CCW) control mode, this signal represents
counterclockwise (CCW) rotation. It is active at both voltage high level and low level. (3).
Minimal DIR signal setup time should be at least 5μs. (4). You can reverse the default rotation
direction by toggling the SW5 DIP switch.
ENA+ I
Enable signal: This signal is used for enabling/disabling the drive. High voltage level of 5-24V
(NPN control signal) for enabli ng the dr iv e and l ow vol tage lev el of 0-0.5VDC for disabling the
ENA- I
By default this signal is left UNCONNECTED & ENABLED.
ALM+ O
Configurable Digital Output Signal: A configurable OC output signal. It takes a sinking or
sourcing 20mA current at 5-24V. It can to be configured as one of the 3 types, FAULT
OUTPUT (default), IN POSITION, or BRAKE CONTROL through Leadshine ProTuner CS-D
ALM- O
software.
Notes: (1) Shielding control signal wires is suggested; (2) to avoid/reduce interference, don’t tie control signal cables
and power wires together.
b) Fault Output, In Position, or Brake control Output Configuration
The digital output on the P1 connector, marked as ALM+ & ALM-, is software configurable (read ProTuner CS-D
software manual). It can be configured as one of the available 3 options – “Fault Output”, “In Position”, and “Brake
Control”. Those 3 options are described as below:
• Fault Output
The FAULT output is the default configuration. It signals a fault condition of CS-D508, including over-voltage,
over-current, or position following error. This output can be used to drive devices such as a relay, a LED, etc.; or as
an input signal for a PLC or I/O devices.
For example, for a multi-axis CNC machine, when one of the axes fails, such a fault output signal can be sent to
the motion controller of the machine and trigger an automatic machine shutdown.
• In Position
Use Leadshine ProTuner for CS-D software to configure this output as an IN POSITION output. In this case a
digital output signal will be sent out, when the targeted position is in the “Target Range” (refer to parameter
Distance to Send "In position" Output Signal in software manual).
• Brake Control
Use Leadshine ProTuner for CS-D software to configure this output as a BRAKE CONTROL output. In this case,
this signal can be used for automatic brake control while system power failure.
Page | 5
Page 10

CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
+24VDC
GND
CS-D508
ALM+
ALM-
Brake
Coil
24VDC
Relay
Controller
Control Signal
Connector
PUL+
1
DIR+
3
PUL-
DIR-
2
4
ENA+
5
ENA-
6
VCC = 5-24V
5V recommended
Step
Direction
Enable
VCC
VCC
VCC
Fault
5V
ALM+
1
2
ALM-
Status Signal
Connector
CS-D508
Controller
Control Signal
Connector
VCC = 5-24V
5V recommended
Fault
5V
ALM+
1
2
ALM-
Status Signal
Connector
CS-D508
PUL+
1
DIR+
3
PUL-
DIR-
2
4
ENA+
5
ENA-
6
5-24V
5V recommended
Step
Direction
Enable
It is recommended to connect a fly-wheel diode in parallel to a 24VDC relay and brake coil connection. Refer to
the following figure for brake connection.
3.1.2 Typical Control and Fault Output Connections
The CS-D508 can accept differential and single-ended control signal inputs (open-collector and PNP outp ut) . A CSD508 has 3 optically isolated control inputs, PUL, DIR, and ENA. Refer to the following two figures for connections
of open-collector and PNP signals.
Figure 3: Connections to PNP signal Figure 4: Connections to open-collector signal
Page | 6
Page 11
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
(Common-cathode) (Common-anode)
3.2 Connector P2 - Encoder Connection
The P2 connector in Figure 2 is for encoder signal connection. Refer to the following table for details.
Drive Pin Name Description
EB+
EB-
EA+
EA-
VCC
EGND
Encoder B+ input connection
Encoder B- input connection
Encoder A+ input connection
Encoder A- input connection
Encoder +5V voltage output connection
Power ground connection
Notes: encoder resolution must be 1000-line.
3.3 Connector P3 - Motor Connecti on
The P3 connector in Figure 2 is for motor connection. Refer to the following table for details.
Pin Name Details
A+
A-
Stepper motor A+ connection. Connect motor A+ wire to this pin
Stepper motor A- connection. Connect motor A- wire to this pin
B+
B-
Stepper motor B+ connection. Connect motor B+ wire to this pin
Stepper motor B- connection. Connect motor B- wire to this pin
3.4 Connector P4 – Power Supply Co nnect io n
The P4 connector in Figure 2 is for power supply connection. Refer to the following table for details.
Pin Name Details
+Vdc
GND
Power supply positive connection. 20-50VDC power supply voltage
Power supply ground connection.
Notes: see Appendix B for compatible Leadshine power supplies
Page | 7
Page 12
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
Pin
NC - Not connected.
GND
GND
Ground.
3.5 Connector P5 – RS232 Connection
The P5 connector in Figure 2 is a RS232 communication port for PC connection. Refer to the following pin definitions.
RS232 Communication Port – RJ11
Name
1
2
3
4
5
6
Notes: RS232 connection of CS-D508 is for tuning purpose only, not for RS232 command controls.
3.6 LED Light Indication
There are two LED lights for CS-D508, one red and one green. The GREEN one is the power indicator which will be
always on generally. The RED one is a protection indicator. It is off always when a CS-D508 operates normally, but
will flash 1, 2 or 7 times in a 5-second period when error protection is enabled. Different number of flashes indicates
different protection type (read Section 9).
+5V O +5V power output.
TxD O RS232 transmit.
RxD I RS232 receive.
NC - Not connected.
4. Motor Selection
The CS-D508 is designed to power 2-phase (or 4-phase 0.9 degree) NEMA 17/23/24 stepper motors under 10000-line
incremental encoders (recommend 1000-line). Leadshine offers many high performance stepper motors compatible
with the CS-D508 which you can find in the Appendix A of this document. The CS-D508 can also power similar
stepper motors with incremental encoders from third-party suppliers.
5. Power Supply Selection
The CS-D508 can power small and medium size closed loop stepper motors (frame size from NEMA17 to 24) from
Leadshine (see Appendix A) or other motor manufacturers. To get good system performance, it is important to select
proper supply voltage and output current. Generally speaking, supply voltage determines the high speed performance
of the motor, while output current determines the output torque of the driven motor (particularly at lower speed).
Higher supply voltage will allow higher motor speed to be achieved, at the price of more noise and heating. If the
motion speed requirement is low, it’s better to use lower supply voltage to decrease noise, heating and improve
Page | 8
Page 13
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
reliability.
Notes: See Appendix B at the end of this document for Leadshine CS-D508 compatible switching power supplies
specially designed for stepper & servo controls.
5.1 Regulated or Unregulat ed Power Sup ply
Both regulated and unregulated power supplies can be used to supply the drive. However, unregulated power supplies
are preferred due to their ability to withstand current surge and fast response for current change. If you prefer to a
regulated power supply, it is suggested to choose such a power supply specially designed for stepper/servo controls
such as Leadshine RPS series (http://www.leadshine.com/producttypes.aspx?producttype=regulated-switching
). Or, in
the case when only normal switching power supplies are available, it is important to use “OVERSIZE” high current
output rating power supplies (for example, using a 4A power supply for 3A stepper motor) to avoid problems such as
current clamp. On the other hand, if unregulated supply is used, one may use a power supply of lower current rating
than that of motor (typically 50%-70% of motor current). The reason is that the drive draws current from the power
supply capacitor of the unregulated supply only during the ON duration of the PWM cycle, but not during the OFF
duration. Therefore, the average current withdrawn from power supply is considerably less than motor current. For
example, two 3A motors can be well supplied by one power supply of 4A rating.
5.2 Power Supply Sharing
Multiple CS-D508 drives can share one power supply to save space and reduce cost, if that power supply has enough
power capacity. To avoid cross interference, connect each stepper drive directly to the shared power supply separately.
To avoid cross interference, DO NOT daisy-chain connect the power supply input pins of the Drivers. Instead connect
them to power supply separately.
5.3 Selecting Supply Voltage
The CS-D508 is designed to operate within 20-50VDC voltage input. When selecting a power supply, besides voltage
from the power supply power line voltage fluctuation and back EMF voltage generated during motor deceleration
needs also to be taken into account. Ideally it is suggested to use a power supply with the output of 20-48VDC, leaving
room for power line voltage fluctuation and back-EMF.
Higher supply voltage can increase motor torque at higher speeds, thus helpful for avoiding losing steps. However,
higher voltage may cause bigger motor vibration at lower speed, and it may also cause over-voltage protection or even
drive damage. Therefore, it is suggested to choose only sufficiently high supply voltage for intended applications.
6. DIP Switch Configurat ions
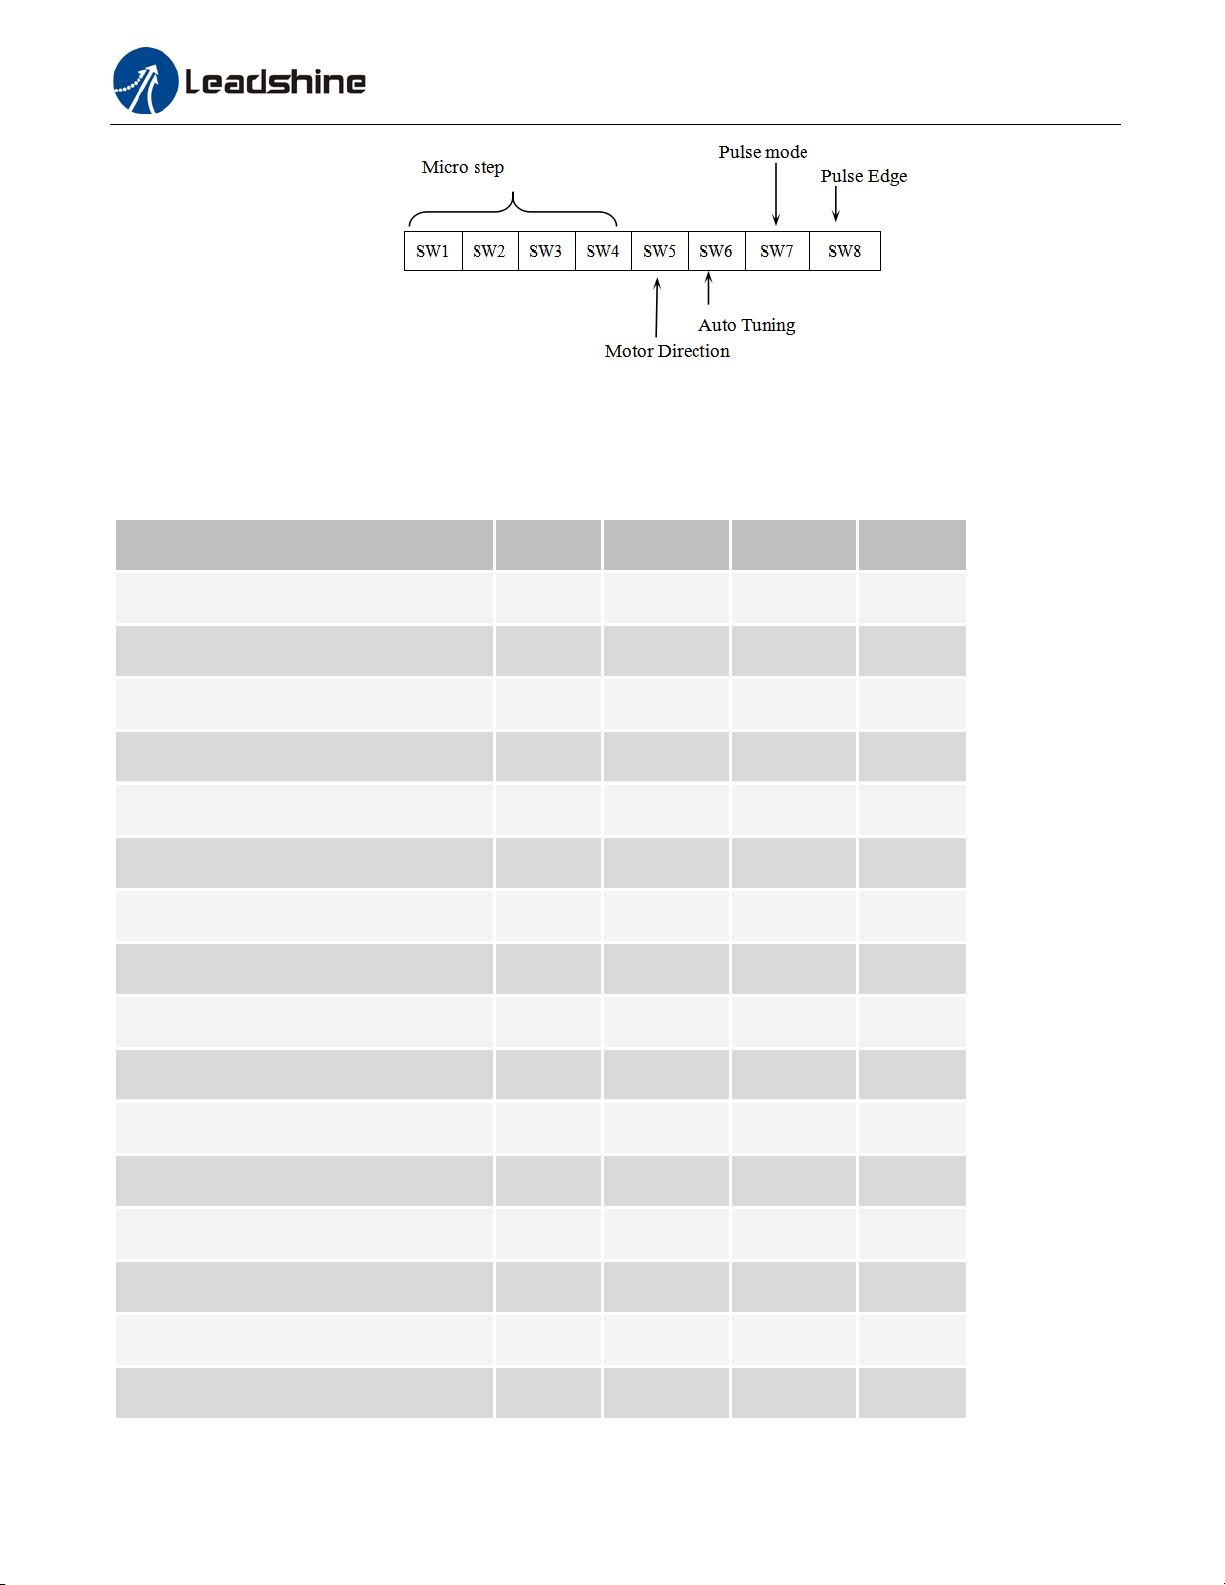
The CS-D508 has a built-in 8-bit DIP switch to set microstep resolution, motor direction, auto-tuning switch and so on.
Page | 9
Page 14
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
Figure 5 DIP switch Setting
6.1 Microstep Resolution (SW1-SW4)
Microstep resolution is set by SW1, 2, 3, 4 of the DIP switches as shown in the following table:
Steps/Revolution SW1 SW2 SW3 SW4
Software Configured (Defaulted to 1600)
800
1600
3200
6400
12800
25600
51200
1000
2000
4000
on on on on
off on on on
on off on on
off off on on
on on off on
off on off on
on off off on
off off off on
on on on off
off on on off
on off on off
5000
8000
10000
20000
40000
off off on off
on on off off
off on off off
on off off off
off off off off
Page | 10
Page 15
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
GND
A+
A-
+Vdc
Encoder Signal
Connector
1
5
6
Power &
Motor Connector
Controller
Black
Red
Control Signal
Connector
4
PUL+
1
DIR+
3
PUL-
DIR-
2
4
ENA+
5
ENA-
6
5V
Step
Direction
Enable
EA+: BLK EA-: BLU
EB+: YEL EB-: GRN
+5V: RED GND: WHT
Fault
5V
ALM+
1
2
ALM-
Status Signal
Connector
24-48VDC recommended,
leaving rooms for voltage fluctuation
and back EMF of the motor
2
Encoder
Extension Cable*
Encoder
Cable
*must be used
Power
Extension Cable
Power
Cable
3
B+
B-
Yellow/Green
Blue
CS-D508
6.2 Other DIP Switch Settings (SW5-SW8)
Function On Off
SW5
SW6
SW7
SW8
Default Direction
Auto Tuning No Yes
Pulse Model CW/CCW (double pulse) PUL/DIR (single pulse)
Pulse Edge Falling Rising
CW (clockwise) CCW (counterclockwise)
7. Typical Connection
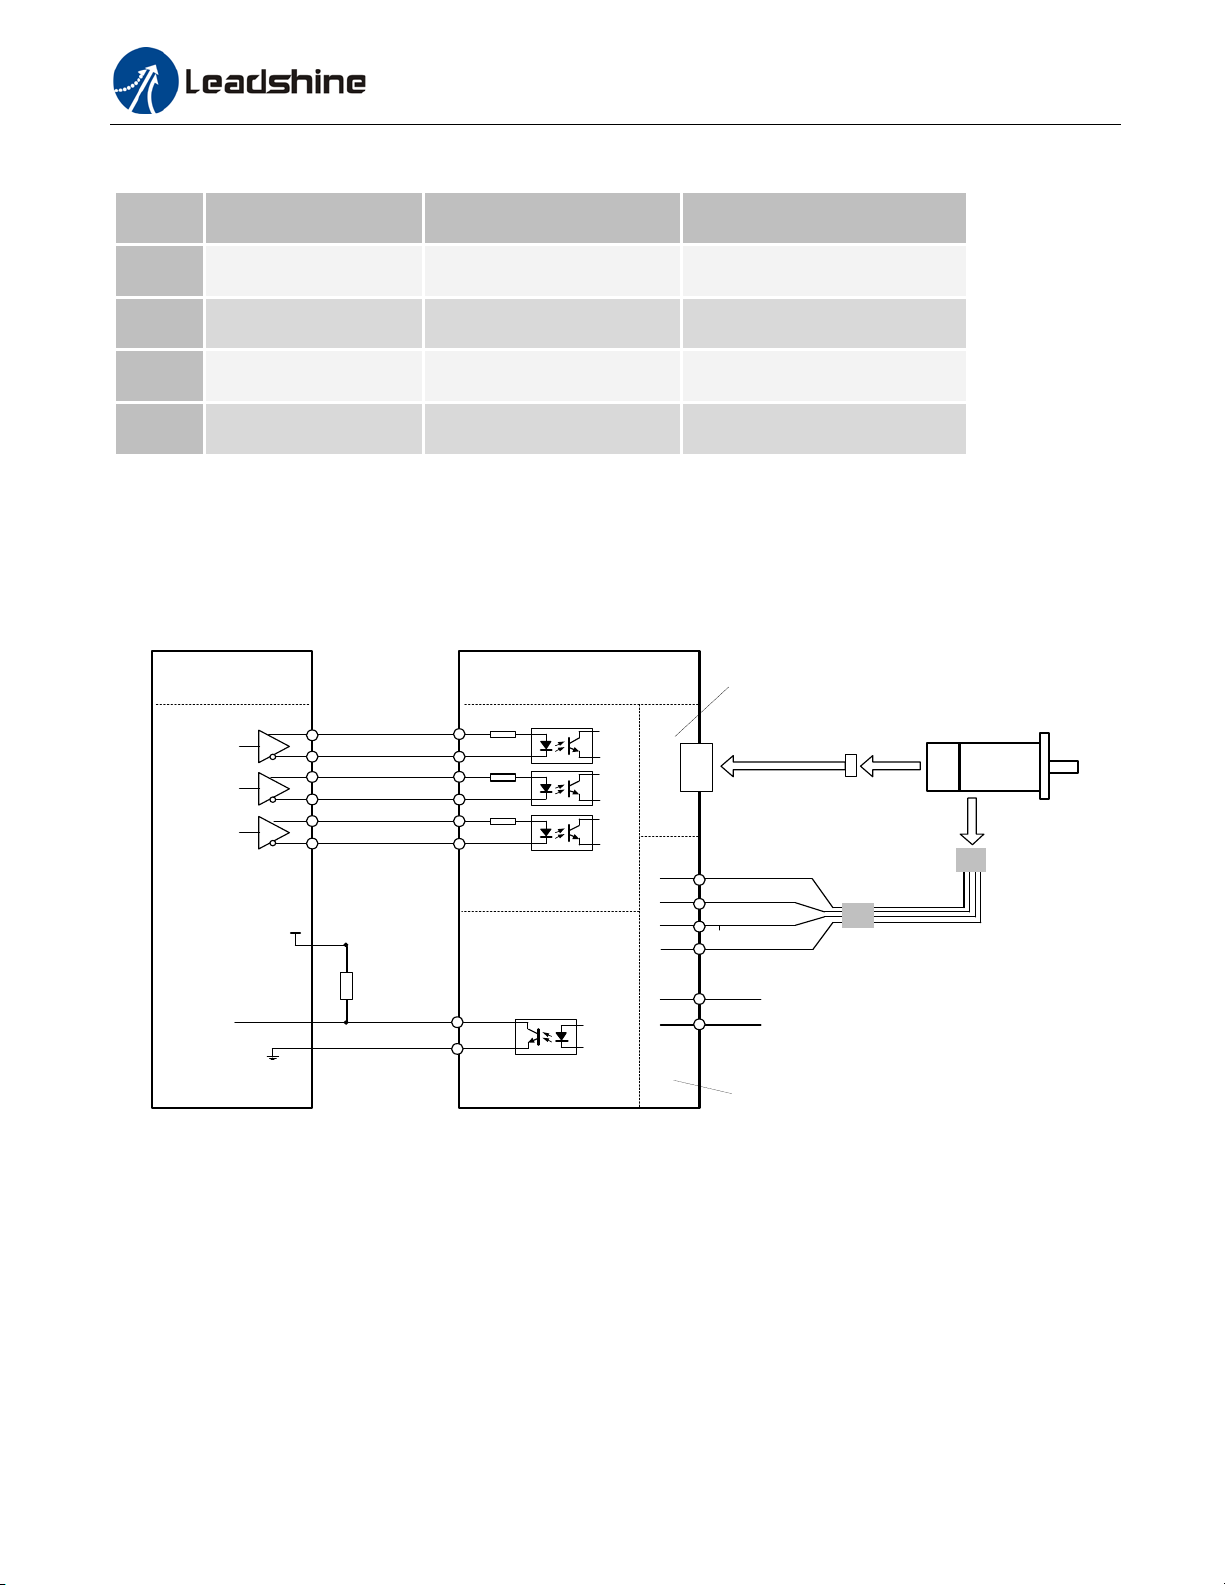
A complete closed loop stepper system should include a stepper motor with encoder, CS-D508 drive, power supply and
controller (pulse generator). A typical connection is illustrated in figure 6.
8. Sequence Chart of Control Signals
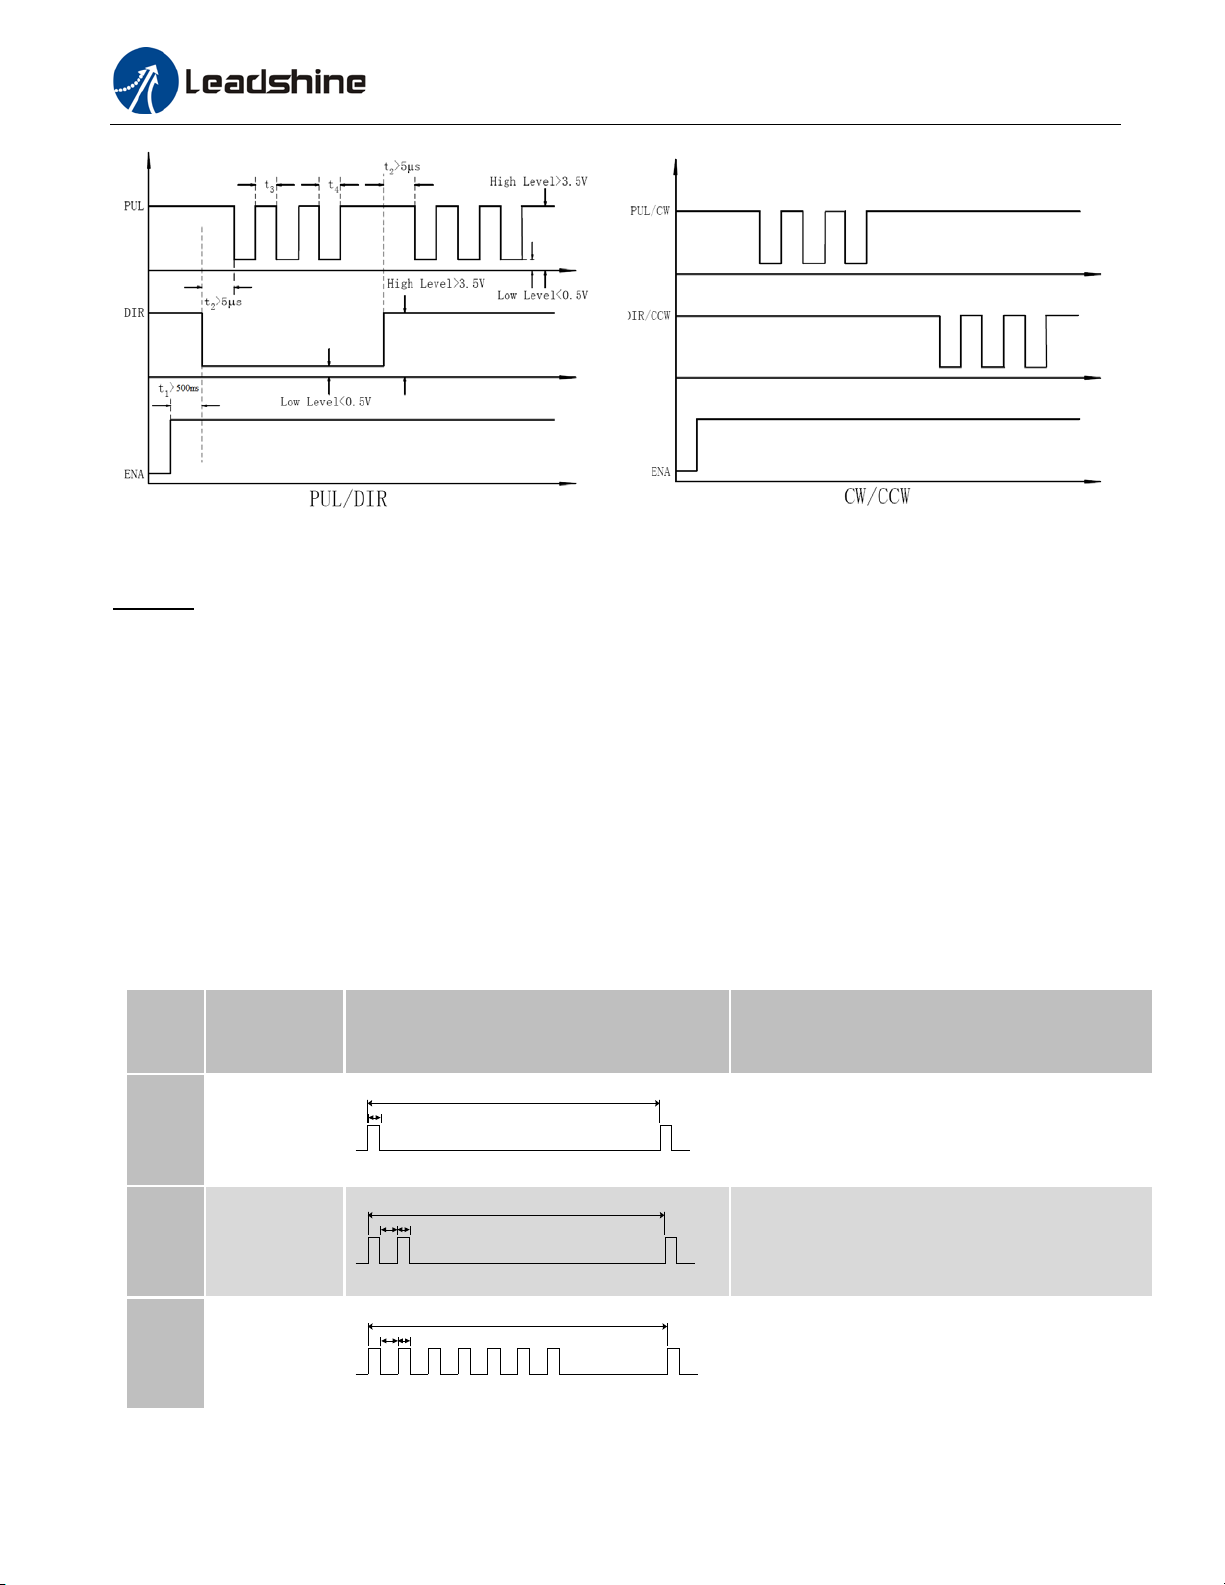
In order to avoid some fault operations and deviations, PUL, DIR and ENA should abide by some rules, shown as
following diagram:
Figure 6: Typical connection
Page | 11
Page 16
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
Priority
0.2S
5S
0.2S
0.3S
5S
0.2S
0.3S
5S
Figure 7: Sequence chart of control signals
Remark:
a) t1: ENA must be ahead of DIR by at least 500ms. Usually, ENA+ and ENA- are NC (not connected). See
“Connector P1 Configurations” for more information.
b) t2: DIR must be ahead of PUL effective edge by 5us to ensure correct direction;
c) t3: Pulse width not less than 2.5us;
d) t4: Low level width not less than 2.5us.
9. Fault Protections
To improve reliability, the drive incorporates some built-in protection features.
1st
2nd
Time(s) of
Blink
1
2
Sequence wave of red LED Description
Over-current protection activated when peak
current exceeds the limit.
Over-voltage protection activated when drive
working voltage is greater than 90VDC
3nd
7
Position following error
Page | 12
Page 17
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
When above protections are active, the motor shaft will be free or the red LED blinks. Reset the drive by repowering it
to make it function properly after removing above problems.
10. Software Confi guration
The CS-D508 is designed for simple setup and implementation. For most applications no software configuration or
tuning is needed especially when driving Leadshine stepper motors with encoders (see Appendix A). If you want to do
fine tuning or custom configurations such as micro-step, current percentage change…, you can use Leadshine’s free
ProTuner software to make the changes.
1 1. Access ories
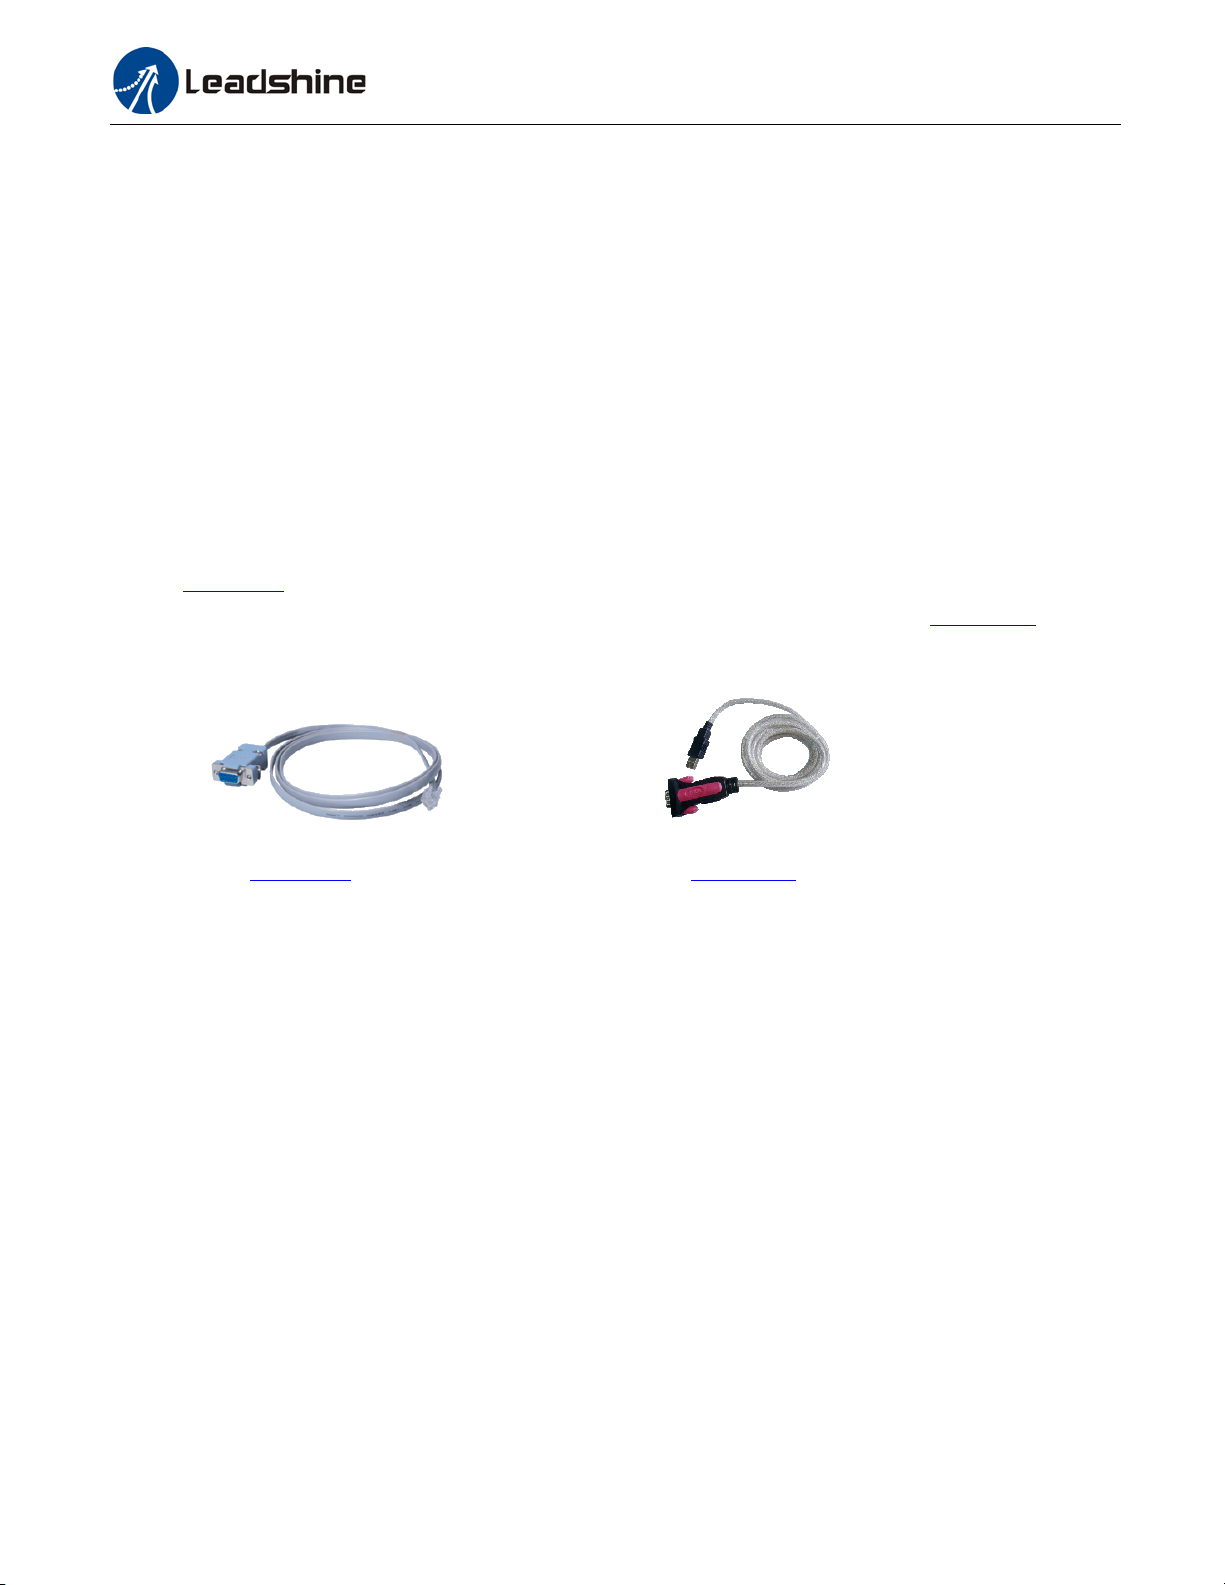
If you plan to use the ProTuner software, contact your supplier or Leadshine to purchase the RS232 cable with part
number CABLE-PC
USB to RS232 conversion, contact your supplier or Leadshine for such a cable with part number USB2.0-232 which
has been verified working fine.
for connecting the CS-D508 to a computer with Windows 7/8/10 installed. In the case of using
CABLE-PC USB2.0-232
(RS232 tuning cable) (USB to RS232 Conversion Cable)
Page | 13
Page 18

CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
12. Troubleshoot ing
In the event that your drive doesn’t operate properly, the first step is to identify whether the problem is electrical or
mechanical in nature. The next step is to isolate the system component that is causing the problem. As part of this
process you may have to disconnect the individual components that make up your system and verify that they operate
independently. It is important to document each step in the troubleshooting process. You may need this documentation
to refer back to at a later date, and these details will greatly assist our Technical Support staff in determining the
problem should you need assistance.
Many of the problems that affect motion control systems can be traced to electrical noise, controller software errors, or
mistake in wiring.
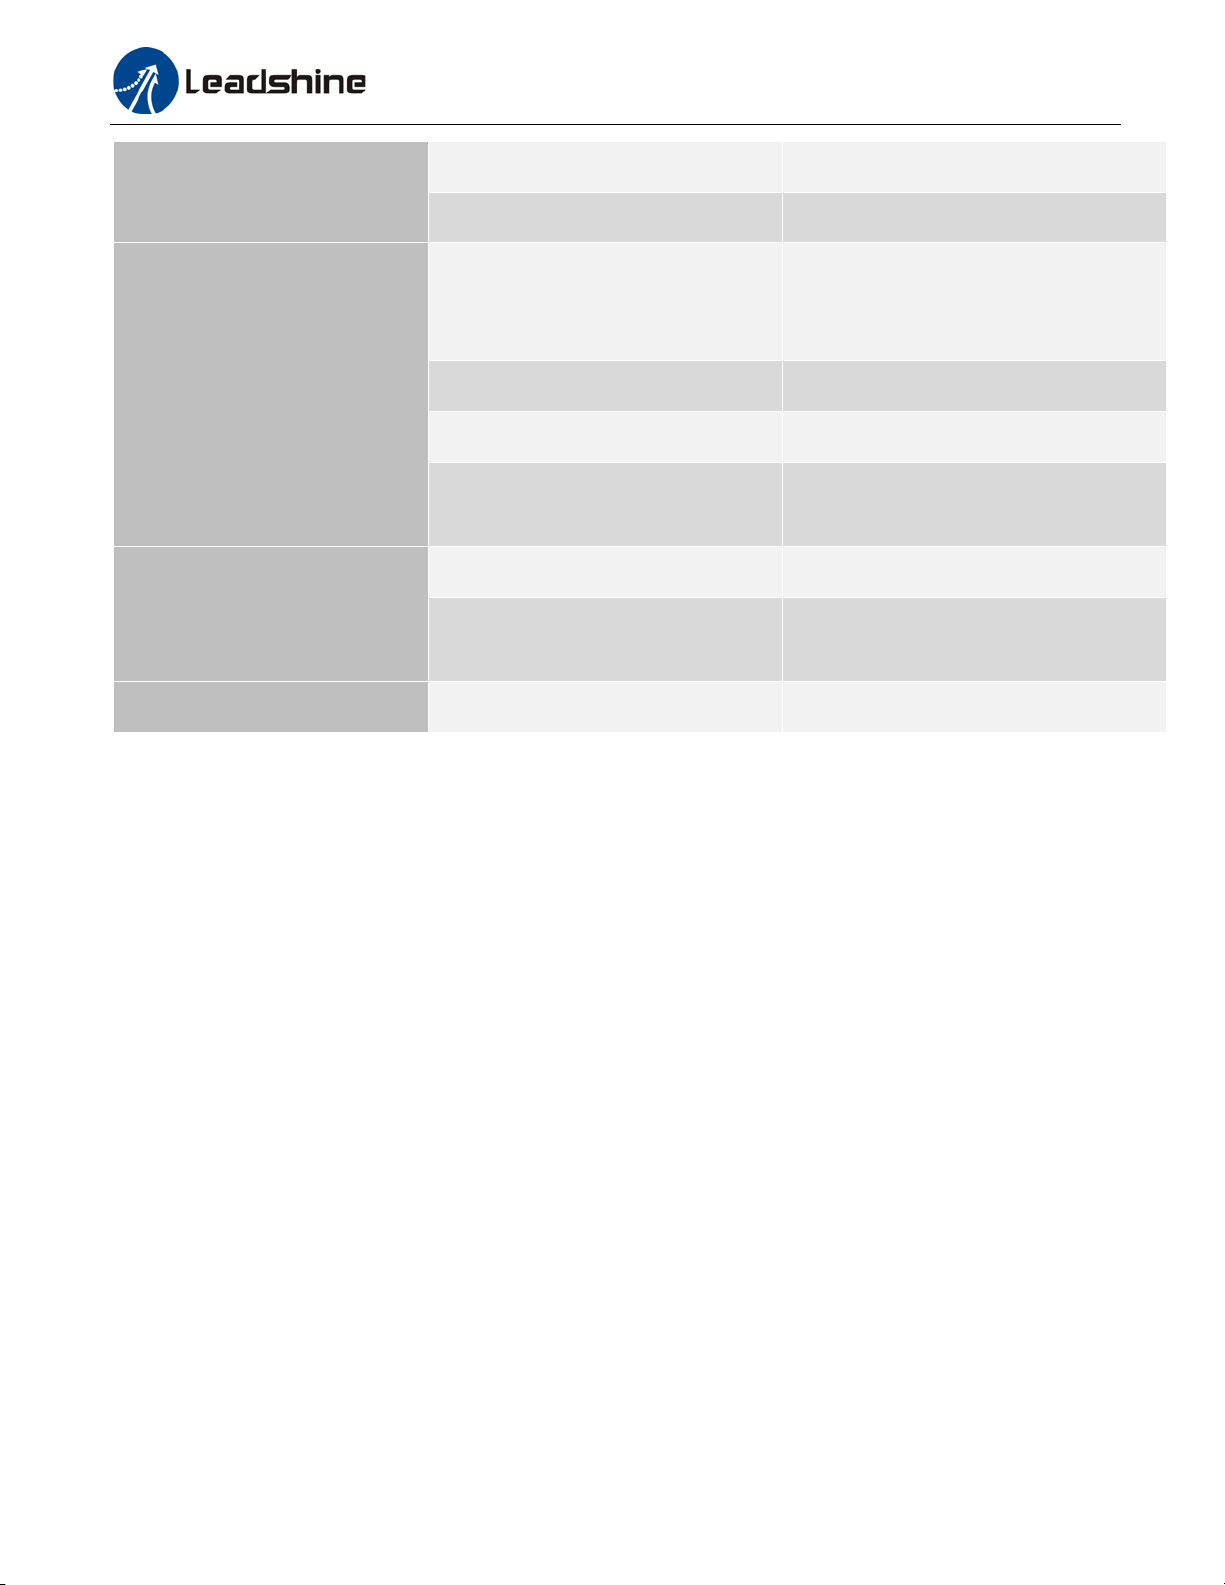
Symptoms Possible Problems Solutions
No power Connect power supply correctly
Microstep resolution setting is wrong Setting appropriate microstep
Motor is not rotating
Wrong motor rotation direction
The drive in fault
Fault condition exists Check wiring and restart power
Drive restore factory setting, and keep
The drive is disabled
ENA+, ENA- input signals unconnected.
The Direction signal level is reverse Toggling the SW5 DIP switch
Red light flashes once in a 5-second
period
Red light flashes twice in a 5-second
period
The motor coil may short circuit or exiting
the wrong wiring
The power supply exceeds Max. operation
voltage
If using Leadshine’s motor, refer to motor
Red light flashes 7-times in a 5-second
period
wiring in datasheet;If using 3rd motor,
need to swap the wiring of motor phase
A+ and phase A-
Red light is always on after power on The drive is burned
Ensure the current of control signal is
Control signal is too weak
within 7-16mA
Erratic motor motion
Control signal is interfered
Wrong motor connection
Don’t tie the control signal cable with
power cable together
Refer to user manual of drive and motor
Page | 14
Page 19
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
datasheet
Something wrong with motor coil Check the motor is normal
Choose another power supply with lager
Current setting is too small
power or increase the output current of
drive
Motor stalls during acceleration
Excessive motor & drive heating
Motor vibration when powe r on
Motor is undersized for the application Choose another motor with higher torque
Acceleration is set too high Reduce the acceleration
Choose another power supply with large
Power supply voltage too low
voltage output
Inadequate heat sinking / cooling Refer to chapter 2.4
Reduce the current value refer to motor
Motor peak current setting is too high
datasheet
Speed loop Kp is too high Reduce the speed loop Kp value
Page | 15
Page 20
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
13. W arr anty
T welve Month W arranty
Leadshine Technology Co., Ltd. warrants its products against defects in materials and workmanship for a period of 12
months from shipment out of factory. During the warranty period, Leadshine will either, at its option, repair or replace
products which proved to be defective.
Exclusions
The above warranty does not extend to any product damaged by reasons of improper or inadequate handlings by
customer, improper or inadequate customer wirings, unauthorized modification or misuse, or operation beyond the
electrical specifications of the product and/or operation beyond environmental specifications for the product.
Obtaining Warranty Service
To obtain warranty service, please contact your seller to obtain a returned material authorization number (RMA) before
returning product for service.
Shipping Failed Products
If your product fail during the warranty period, please contact your seller for how and where to ship the failed product
for warranty or repair services first, you can also e-mail customer service at [email protected]
to obtain a returned
material authorization number (RMA) before returning product for service. Please include a written description of the
problem along with contact name and address.
Page | 16
Page 21

CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
Appendix A. Leadshine CS-D508 Comp atible Stepper Motors
The following Leadshine stepper motors with 1000-line encoders have been confirmed working with the CS-D508
closed loop stepper drive.
Model
CS-M21702
CS-M21704
CS-M21706
CS-M21708
CS-M22306
CS-M22313
CS-M22323
CS-M22323-S
CS-M22326
CS-M22326-S
Frame Size
(NEMA)
17
Torque
Series
(N.m / Oz-In)
0.2 / 28
Length
Notes
(mm / inch)
56/2.20 -
0.4 / 57 63/2.48 -
0.6 / 85 70/2.76 -
0.8 / 113 83/3.27 -
0.6 / 85 62/2.44 -
1.3 / 184 77/3.03 -
2.3 / 326 97/3.82 -
2.3 / 326 97/3.82 0.25-inch (6.35-mm) shaft
2.6 / 368 105/4.13 -
CS-M
2.6 / 368 105/4.13 0.25-inch (6.35-mm) shaft
CS-M22321-L
CS-M22331-L
CS-M22331-L-S
CS-M22313B
CS-M22323B
CS-M22313WP
CS-M22323WP
23
2.1 / 368 88/3.46 -
3.1 / 439 109/4.29 -
3.1 / 439 109/4.29 -
1.3 / 184 109/4.29 24VDC brake integrated
2.3 / 326 131/5.15 24VDC brake integrated
1.2 / 184 95/3.74 IP65 rated
2.0 / 283 114/4.49 IP65 rated
Note: all above stepper motors are mounted with 1000-line incremental encoders
Page | 17
Page 22
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
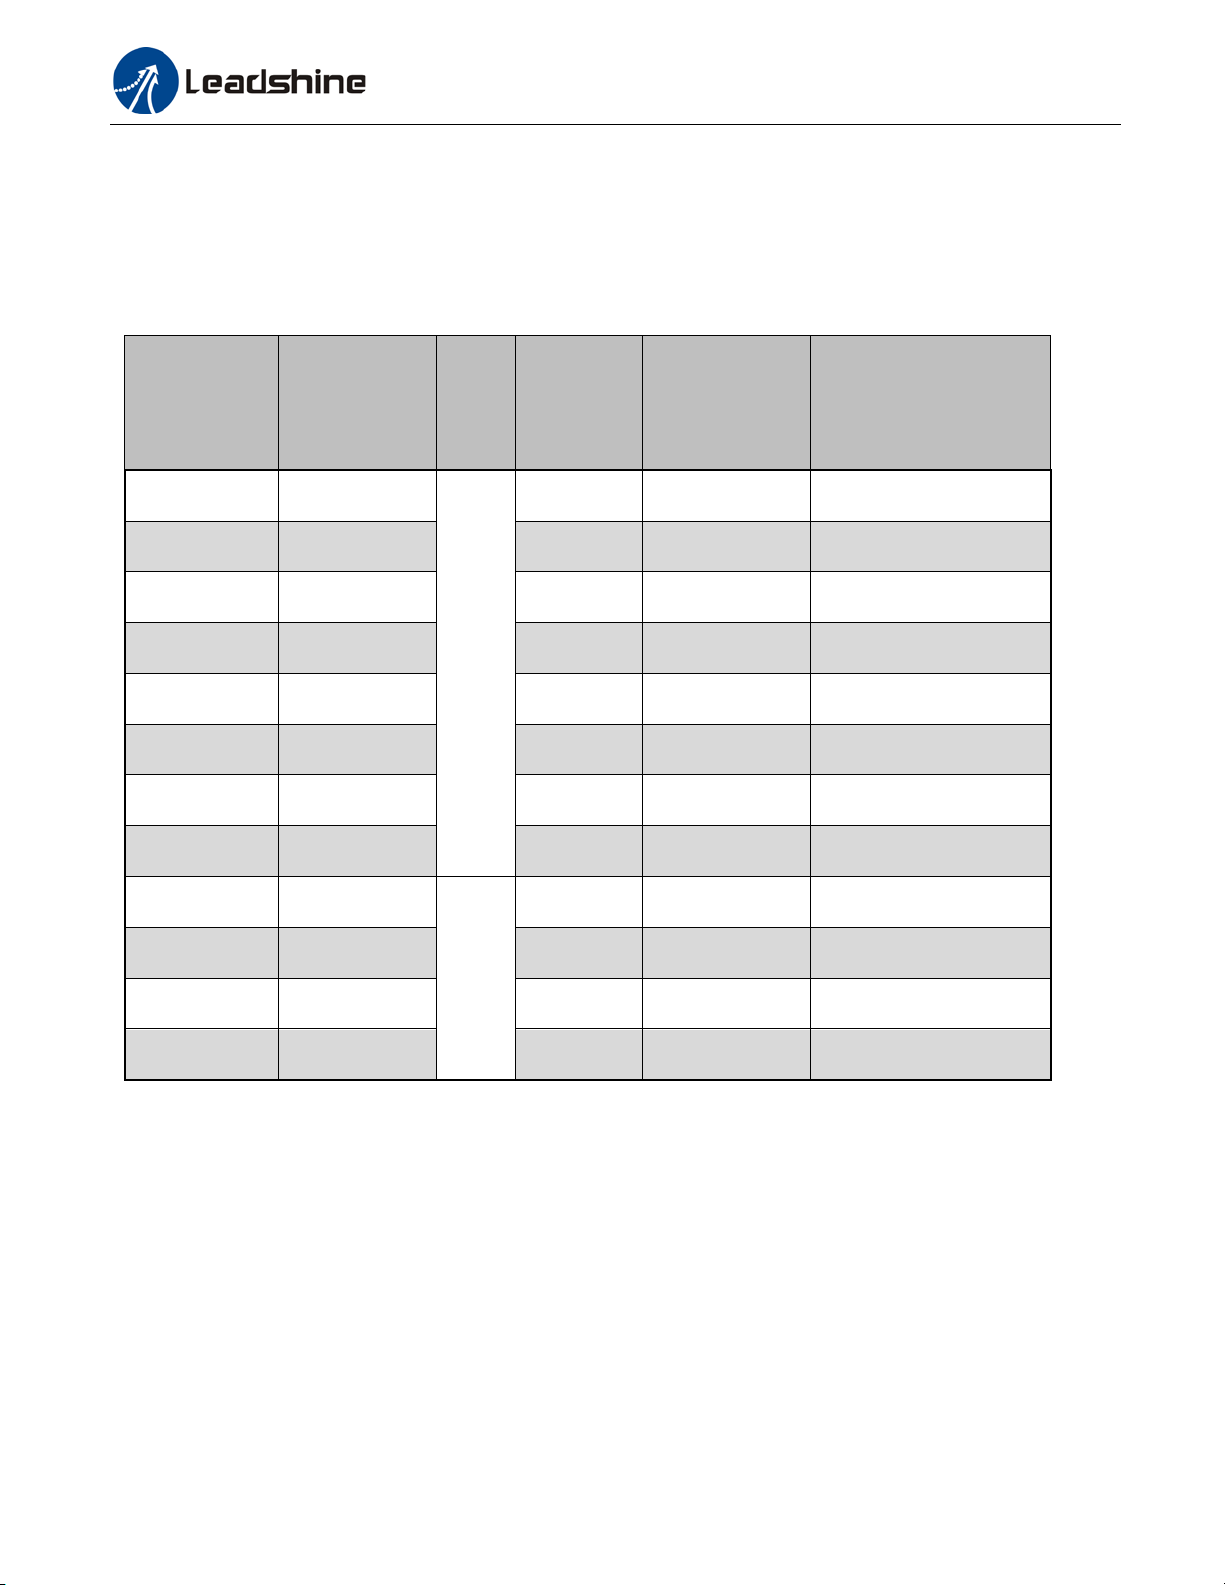
Appendix B. Leadshine CS-D508 Compatible Power Supplies
It is highly suggested to use the following Leadshine power supplies to power CS-D508 to get optimized performance.
Those power supply are specially designed for stepper and servo controls.
Output
Model
RPS2410V20 24
RPS3611V20 36 11 33 85-132 / 176-264
RPS488V20 48 8.3 24.9 85-132 / 176-264
RPS4810V20 48 10.5 31.5 85-132 / 176-264
RPS2410 24 10 12 85-132 / 176-264
RPS369 36 9.7 11 85-132 / 176-264
RPS488 48 7.3 8.5 85-132 / 176-264
RPS4810 48 10.4 12.5 85-132 / 176-264
SPS407 42
Voltage
(VDC)
Series
Model
RPS
Continuous
Current
(A)
10 30 85-132 / 176-264
7.0 9.0 180-240
Max
Current
(A)
Input Voltage
(VAC)
SPS407-L 42 4.7 9.0 90-130
SPS
SPS487 48 7.0 9.0 180-240
SPS487-L 48 3.0 9.0 90-130
Page | 18
Page 23
CS-D508 Closed Loop Stepper Drive User Manual Version 3.1
Appendix C. Powering a Third Party Motor with CS-D508
To get the best system performance and most convenience for setup, it is highly recommended to choose a Leadshine
closed stepper motor along with the CS-D508 closed loop stepper drive. See Appendix A for frequently used Leadshine
closed loop stepper motors. If you can’t find one meeting your requirements there, contact Leadshine sales by
emailing [email protected] or [email protected]
one already there which can satisfy your application need already.
In the case of powering a third party closed loop stepper motor, pay special attention as described below.
• Your stepper motor must be a 2-phase stepper motor
• Your stepper motor must be mounted with a quadrature rotary encoder with the resolution of 500-5,000 line
(2,000- 20,000 counts).
• When the CS-D508 is first-time powered on after your stepper motor is connected, check the following
possible causes if a position following error (see Section 9 above).
o Confirm both encoder and power cables are connected properly and tightly secured.
o Power off the drive then swap the A+ and A- motor connections to the CS-D508 drive. The reason is
the definitions of your Motor A+ and A- are different from those marked on CS-D508 motor
connection pins (P3 of Figure 2).
. Leadshine offers many other custom models. There may be
If protection error is still seen after the above steps, contact your CS-D508 drive or Leadshine technical
support.
Page | 19
 Loading...