

Page 1
User manual
Version:3.0
Page 2
All rights reserved. Except as expressly provided herein, no part of this manual may be
reproduced, copied, transmitted, disseminated, downloaded or stored in any storage medium,
for any purpose without the express prior written consent of Flymaster Avionics Lda. herein
Flymaster Avionics. Flymaster Avionics hereby grants permission to download a copy of this
manual onto a hard drive or other electronic storage medium to be viewed and to print a copy
of this manual or of any revision hereto, provided that such electronic or printed copy of this
manual must contain the complete text of this copyright notice and provided further that any
unauthorised commercial distribution of this manual or any revision hereto is strictly prohibited.
Information in this document is subject to change without notice. Flymaster Avionics reserves
the right to change or improve its products and to make changes in the content without obliga-
tion to notify any person or organisation of such changes or improvements. Visit the Flymaster
Avionics website (www.ymaster-avionics.com) for current updates and supplemental informa-
tion concerning the use and operation of this and other Flymaster Avionics products.
Warning
It is the sole responsibility of the pilot to operate the aircraft in a safe manner, maintain full
surveillance of all ying conditions at all times, and not become distracted by the Flymaster
LIVE SD . Flymaster Avionics is not responsible for any damages resulting from incorrect or no
data provided by the Flymaster LIVE SD . Flight safety is the sole responsibility of the pilot.
It is unsafe to operate the Flymaster LIVE SD while in the air. Failure by the pilot equipped
with a Flymaster LIVE SD to pay full attention to the aircraft and ying conditions while ying
could result in accident with property damage and/or personal injury.
Page 3
Contents
Page
1 Getting Started 4
1.1 Charging the Battery . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 4
1.2 LIVE SD Keys . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 4
1.3 Using keys Inside Menu . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 5
1.4 Switching LIVE SD On and O . . . . . . . . . . . . . . . . . . . . . . . . . . . . 5
1.5 Resetting the LIVE SD . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 6
1.6 Setting the Volume . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 6
1.7 Flight Start and Recording . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 6
2 Flight Mode 7
3 LIVE SD Elements 8
3.1 Graphical Elements . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
3.1.1 Battery . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
3.1.2 Sound . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
3.1.3 Mobile Operator . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
3.1.4
3.1.5 Vario . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
3.1.6 Navigation Circle . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
3.1.7 Airspaces Map . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
3.1.8 Altitude graph . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
3.1.9 Wind Arrow . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 15
3.1.10 Map Page . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 15
3.1.11 Compass . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 16
3.2 Data eld Elements . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 17
GPS
. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
4 Menu mode 21
4.1 Waypoints and Task . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 22
4.1.1 Waypoints Actions Menu . . . . . . . . . . . . . . . . . . . . . . . . . . . 23
4.1.2 TaskList . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 24
4.2 Task Delay . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 27
4.3 TaskNavigator . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 28
4.4 Critical Airspaces . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 29
4.5 Triangle Assistent . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 30
4.6 Nearby Landings . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 31
4.7 Flight Log . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 32
4.8 Pages . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 34
4.9 Report Back . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 35
2
Page 4
4.10 Settings Menu . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 36
4.10.1 Set Altimeter . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 37
4.10.2 Time . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 38
4.10.3 Vario Acoustics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 38
4.10.4 Alerts . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 40
4.10.5 Advanced Features . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 40
4.10.6 Trace . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 42
4.10.7 Screen . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 44
4.10.8 Language/Units . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 46
4.10.9 Device Settings . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 47
4.10.10RF Probes . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 47
4.10.11Probe Alerts . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 48
4.10.12Calibration . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 49
4.10.13Polar . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 49
4.10.14Data elds . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 50
4.10.15FS Keys . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 50
4.10.16Navigation Settings . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 51
4.10.17Airspace settings . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 52
4.10.18GSM Data . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 53
4.10.19SMS Conguration . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 55
4.10.20GPS status . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 55
5 TaskDenition 57
6 McCready Functions 60
7 Flying a FAI Triangle 61
8 Compass Calibration 64
8.1 Accelerometer Calibration . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 64
8.2 Magnetometer Calibration . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 64
9 Firmware 67
10 Interfacing with GPSDump 69
10.1 Conguring GPSDump . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 69
10.2 Uploading Waypoints . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 70
10.3 Downloading tracklogs . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 72
3
Page 5
1 Getting Started
Fully charge battery before using your Flymaster for the rst time.
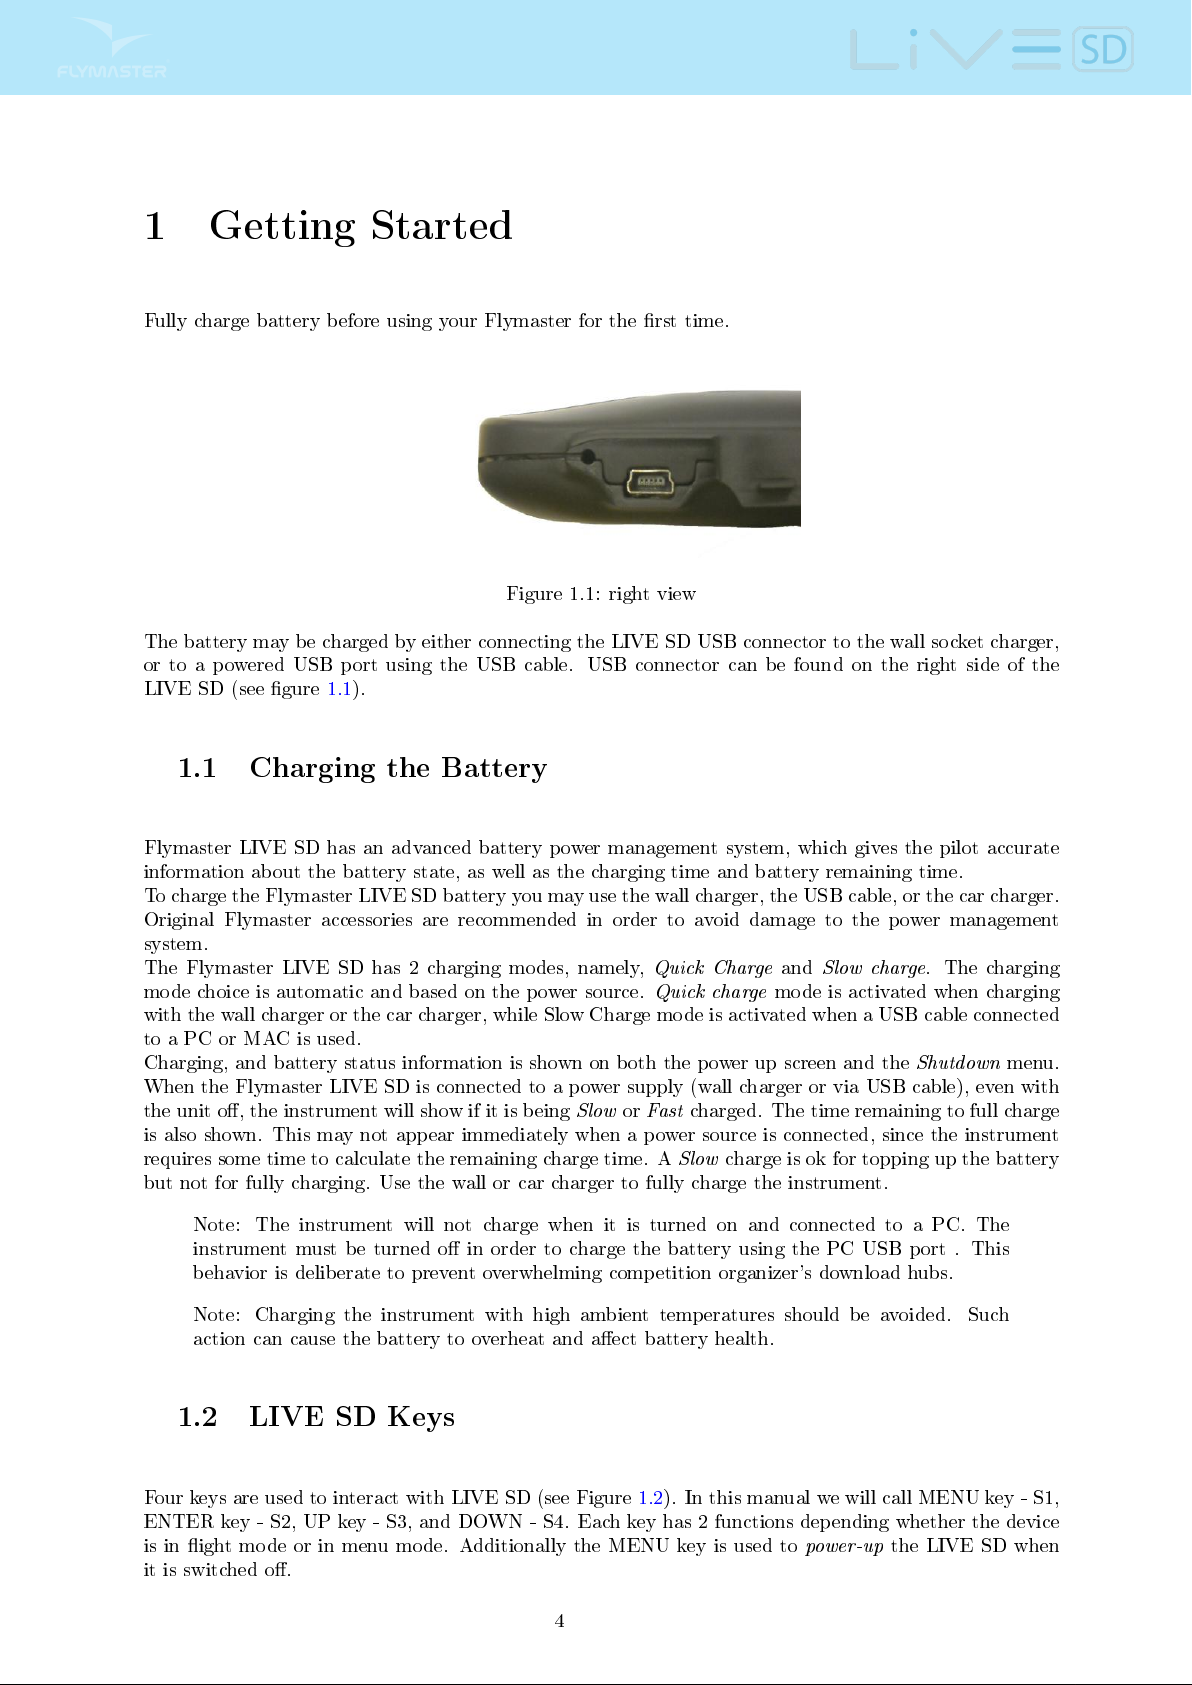
Figure 1.1: right view
The battery may be charged by either connecting the LIVE SD USB connector to the wall socket charger,
or to a powered USB port using the USB cable. USB connector can be found on the right side of the
LIVE SD (see gure 1.1).
1.1 Charging the Battery
Flymaster LIVE SD has an advanced battery power management system, which gives the pilot accurate
information about the battery state, as well as the charging time and battery remaining time.
To charge the Flymaster LIVE SD battery you may use the wall charger, the USB cable, or the car charger.
Original Flymaster accessories are recommended in order to avoid damage to the power management
system.
The Flymaster LIVE SD has 2 charging modes, namely,
mode choice is automatic and based on the power source.
with the wall charger or the car charger, while Slow Charge mode is activated when a USB cable connected
to a PC or MAC is used.
Charging, and battery status information is shown on both the power up screen and the
When the Flymaster LIVE SD is connected to a power supply (wall charger or via USB cable), even with
the unit o, the instrument will show if it is being
is also shown. This may not appear immediately when a power source is connected, since the instrument
requires some time to calculate the remaining charge time. A
but not for fully charging. Use the wall or car charger to fully charge the instrument.
Note: The instrument will not charge when it is turned on and connected to a PC. The
instrument must be turned o in order to charge the battery using the PC USB port . This
behavior is deliberate to prevent overwhelming competition organizer's download hubs.
Note: Charging the instrument with high ambient temperatures should be avoided. Such
action can cause the battery to overheat and aect battery health.
SloworFast
Quick Charge
Quick charge
charged. The time remaining to full charge
Slow
and
Slow charge
mode is activated when charging
charge is ok for topping up the battery
. The charging
Shutdown
menu.
1.2 LIVE SD Keys
Four keys are used to interact with LIVE SD (see Figure 1.2). In this manual we will call MENU key - S1,
ENTER key - S2, UP key - S3, and DOWN - S4. Each key has 2 functions depending whether the device
is in ight mode or in menu mode. Additionally the MENU key is used to
it is switched o.
4
power-up
the LIVE SD when
Page 6
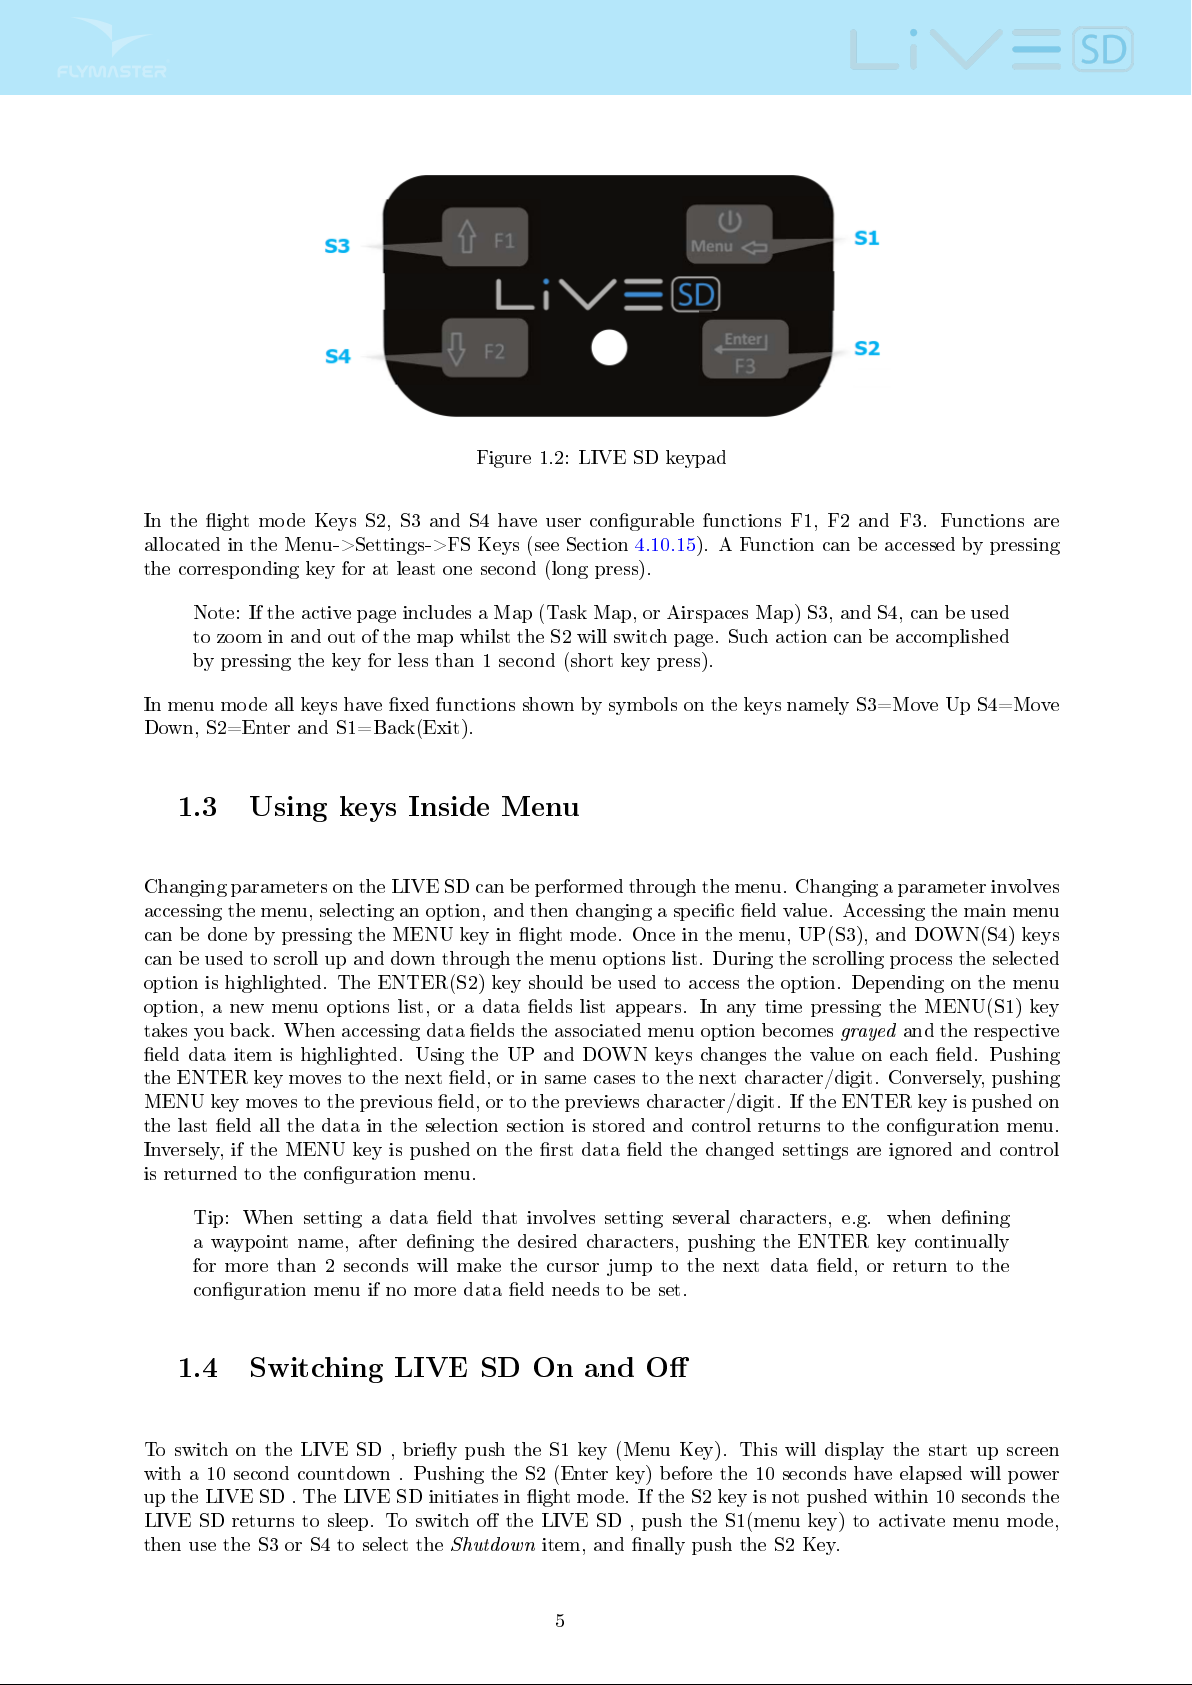
Figure 1.2: LIVE SD keypad
In the ight mode Keys S2, S3 and S4 have user congurable functions F1, F2 and F3. Functions are
allocated in the Menu->Settings->FS Keys (see Section 4.10.15). A Function can be accessed by pressing
the corresponding key for at least one second (long press).
Note: If the active page includes a Map (Task Map, or Airspaces Map) S3, and S4, can be used
to zoom in and out of the map whilst the S2 will switch page. Such action can be accomplished
by pressing the key for less than 1 second (short key press).
In menu mode all keys have xed functions shown by symbols on the keys namely S3=Move Up S4=Move
Down, S2=Enter and S1=Back(Exit).
1.3 Using keys Inside Menu
Changing parameters on the LIVE SD can be performed through the menu. Changing a parameter involves
accessing the menu, selecting an option, and then changing a specic eld value. Accessing the main menu
can be done by pressing the MENU key in ight mode. Once in the menu, UP(S3), and DOWN(S4) keys
can be used to scroll up and down through the menu options list. During the scrolling process the selected
option is highlighted. The ENTER(S2) key should be used to access the option. Depending on the menu
option, a new menu options list, or a data elds list appears. In any time pressing the MENU(S1) key
takes you back. When accessing data elds the associated menu option becomes
eld data item is highlighted. Using the UP and DOWN keys changes the value on each eld. Pushing
the ENTER key moves to the next eld, or in same cases to the next character/digit. Conversely, pushing
MENU key moves to the previous eld, or to the previews character/digit. If the ENTER key is pushed on
the last eld all the data in the selection section is stored and control returns to the conguration menu.
Inversely, if the MENU key is pushed on the rst data eld the changed settings are ignored and control
is returned to the conguration menu.
grayed
and the respective
Tip: When setting a data eld that involves setting several characters, e.g. when dening
a waypoint name, after dening the desired characters, pushing the ENTER key continually
for more than 2 seconds will make the cursor jump to the next data eld, or return to the
conguration menu if no more data eld needs to be set.
1.4 Switching LIVE SD On and O
To switch on the LIVE SD , briey push the S1 key (Menu Key). This will display the start up screen
with a 10 second countdown . Pushing the S2 (Enter key) before the 10 seconds have elapsed will power
up the LIVE SD . The LIVE SD initiates in ight mode. If the S2 key is not pushed within 10 seconds the
LIVE SD returns to sleep. To switch o the LIVE SD , push the S1(menu key) to activate menu mode,
then use the S3 or S4 to select the
Shutdown
item, and nally push the S2 Key.
5
Page 7
1.5 Resetting the LIVE SD
The reset procedure allows the pilot to restart the LIVE SD in the unlikely event that it freezes, or stops
responding (if this ever occur please report it to our support email). To reset the LIVE SD push S1 (Menu)
key and the S4 (Down arrow) key, simultaneously, for at least two seconds. The display will go blank and
after will return in Flight mode.
Note: Resetting the LIVE SD will also reset ight data, e.g. task status.
1.6 Setting the Volume
The LIVE SD sound volume can be adjust using one FS Key, or trough the
the
Settings
current volume level can be seen using the sound element (see Section 3.1.2 for more details).
Pressing the dened FS Key will scroll up the sound level until the maximum value. Pressing more will
mute the sound before start scrolling again starting from the minimum value.
Note: Changing the volume using an FS key is only valid for the current ight, and will not
override the volume level setting. Every time the instrument is turned on, if the sound is
muted, an alarm is generated in order to notify the pilot.
Note: When the instrument is turned on the sound can be muted despite the volume level
settings. This occurs due to the
details)
Menu (see Section 4.10.3). The LIVE SD has six dierent sound levels, plus
Auto silent
mode is activated (see Section 4.10.5 for more
Vario Accoustics
no sound
option of
. The
1.7 Flight Start and Recording
Most of the LIVE SD features are only available after the
to avoid wrong calculations due to missing data. Flight starts when all of there 3 conditions are met:
1. GPS 3d x is established;
2. Speed goes over the congured
Start Speed
(default value is 8km/h)
Flight Start
. This procedure is taken in order
3. Average vario is greater than +-0.15m/s
6
Page 8
2 Flight Mode
The Flymaster LIVE SD has two main working modes, namely Flight mode, and Menu mode. Flight
mode is used during ight, and this allows the user to see information such as Altitude, Speed, or Vario.
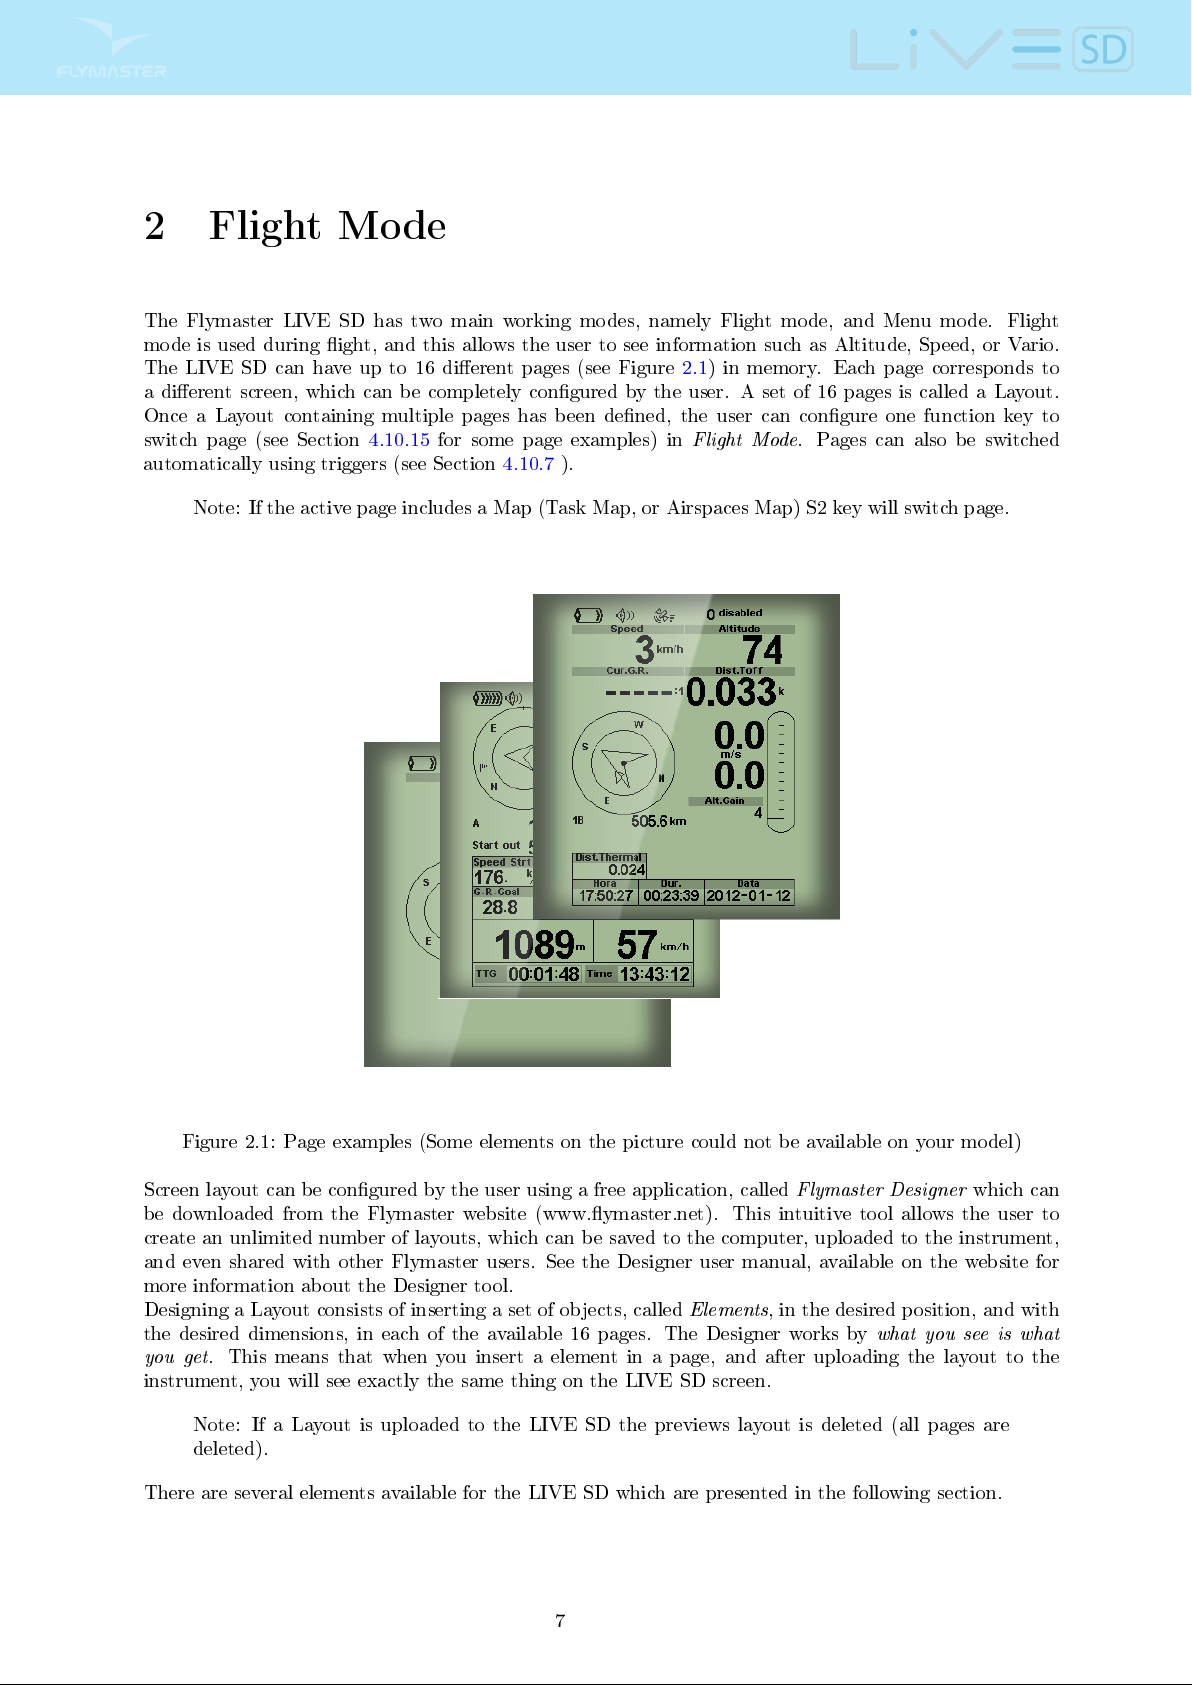
The LIVE SD can have up to 16 dierent pages (see Figure 2.1) in memory. Each page corresponds to
a dierent screen, which can be completely congured by the user. A set of 16 pages is called a Layout.
Once a Layout containing multiple pages has been dened, the user can congure one function key to
switch page (see Section 4.10.15 for some page examples) in
automatically using triggers (see Section 4.10.7 ).
Note: If the active page includes a Map (Task Map, or Airspaces Map) S2 key will switch page.
Flight Mode
. Pages can also be switched
Figure 2.1: Page examples (Some elements on the picture could not be available on your model)
Screen layout can be congured by the user using a free application, called
be downloaded from the Flymaster website (www.ymaster.net). This intuitive tool allows the user to
create an unlimited number of layouts, which can be saved to the computer, uploaded to the instrument,
and even shared with other Flymaster users. See the Designer user manual, available on the website for
more information about the Designer tool.
Designing a Layout consists of inserting a set of objects, called
the desired dimensions, in each of the available 16 pages. The Designer works by
you get
instrument, you will see exactly the same thing on the LIVE SD screen.
There are several elements available for the LIVE SD which are presented in the following section.
. This means that when you insert a element in a page, and after uploading the layout to the
Note: If a Layout is uploaded to the LIVE SD the previews layout is deleted (all pages are
deleted).
7
Elements
Flymaster Designer
, in the desired position, and with
what you see is what
which can
Page 9
3 LIVE SD Elements
The main objective of an element is to provide information to the user. Elements can be Graphical, or
Data Field type. Each element has its own properties which can be changed in order to alter the element
behaviour, and/or shape.
3.1 Graphical Elements
Graphical elements are characterized by providing information in a graphical way. Most of the graphical
elements have xed dimensions, although their position can be altered.
As the LIVE SD rmware evolves the list of Graphical Elements will likely grow. The current list includes
the following graphical elements.
3.1.1 Battery
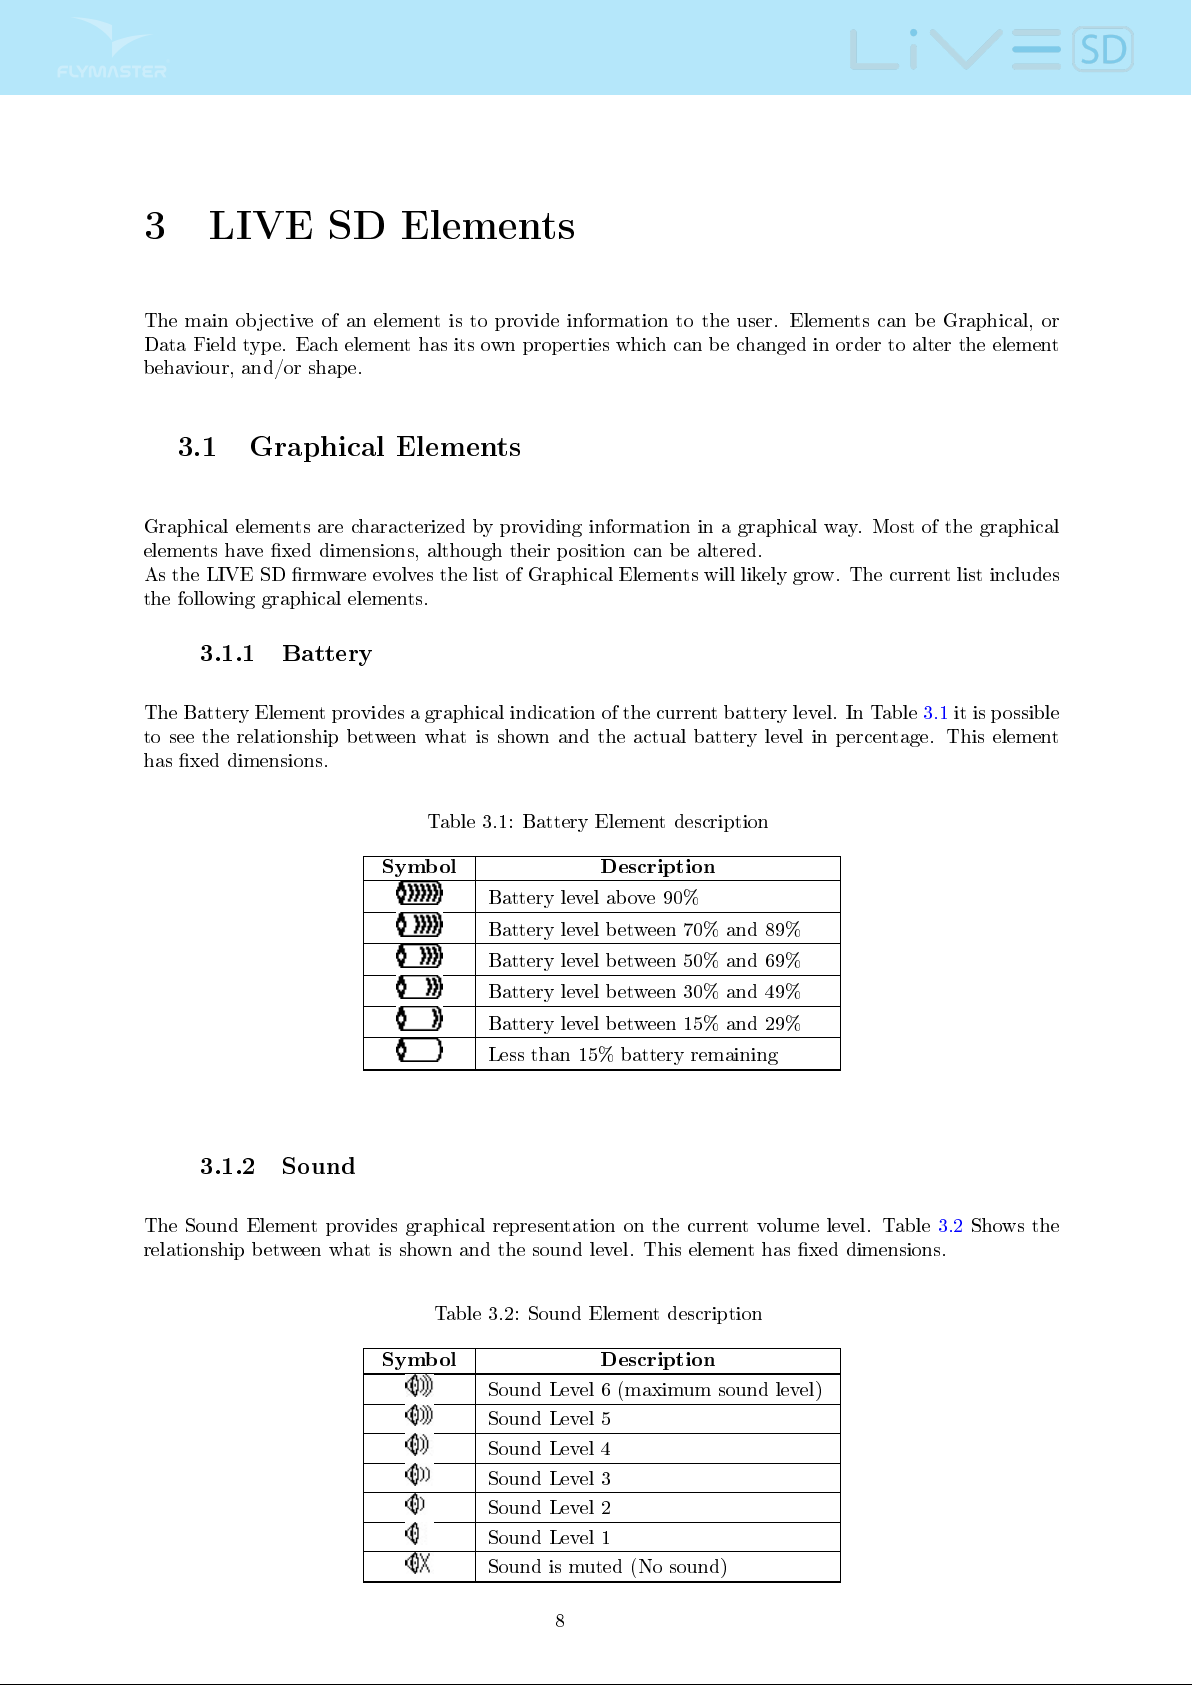
The Battery Element provides a graphical indication of the current battery level. In Table 3.1 it is possible
to see the relationship between what is shown and the actual battery level in percentage. This element
has xed dimensions.
Table 3.1: Battery Element description
Symbol Description
Battery level above 90%
Battery level between 70% and 89%
Battery level between 50% and 69%
Battery level between 30% and 49%
Battery level between 15% and 29%
Less than 15% battery remaining
3.1.2 Sound
The Sound Element provides graphical representation on the current volume level. Table 3.2 Shows the
relationship between what is shown and the sound level. This element has xed dimensions.
Table 3.2: Sound Element description
Symbol Description
Sound Level 6 (maximum sound level)
Sound Level 5
Sound Level 4
Sound Level 3
Sound Level 2
Sound Level 1
Sound is muted (No sound)
8
Page 10
3.1.3 Mobile Operator
The Mobile operator Element, similarly to any mobile phone, provides an indication about the commu-
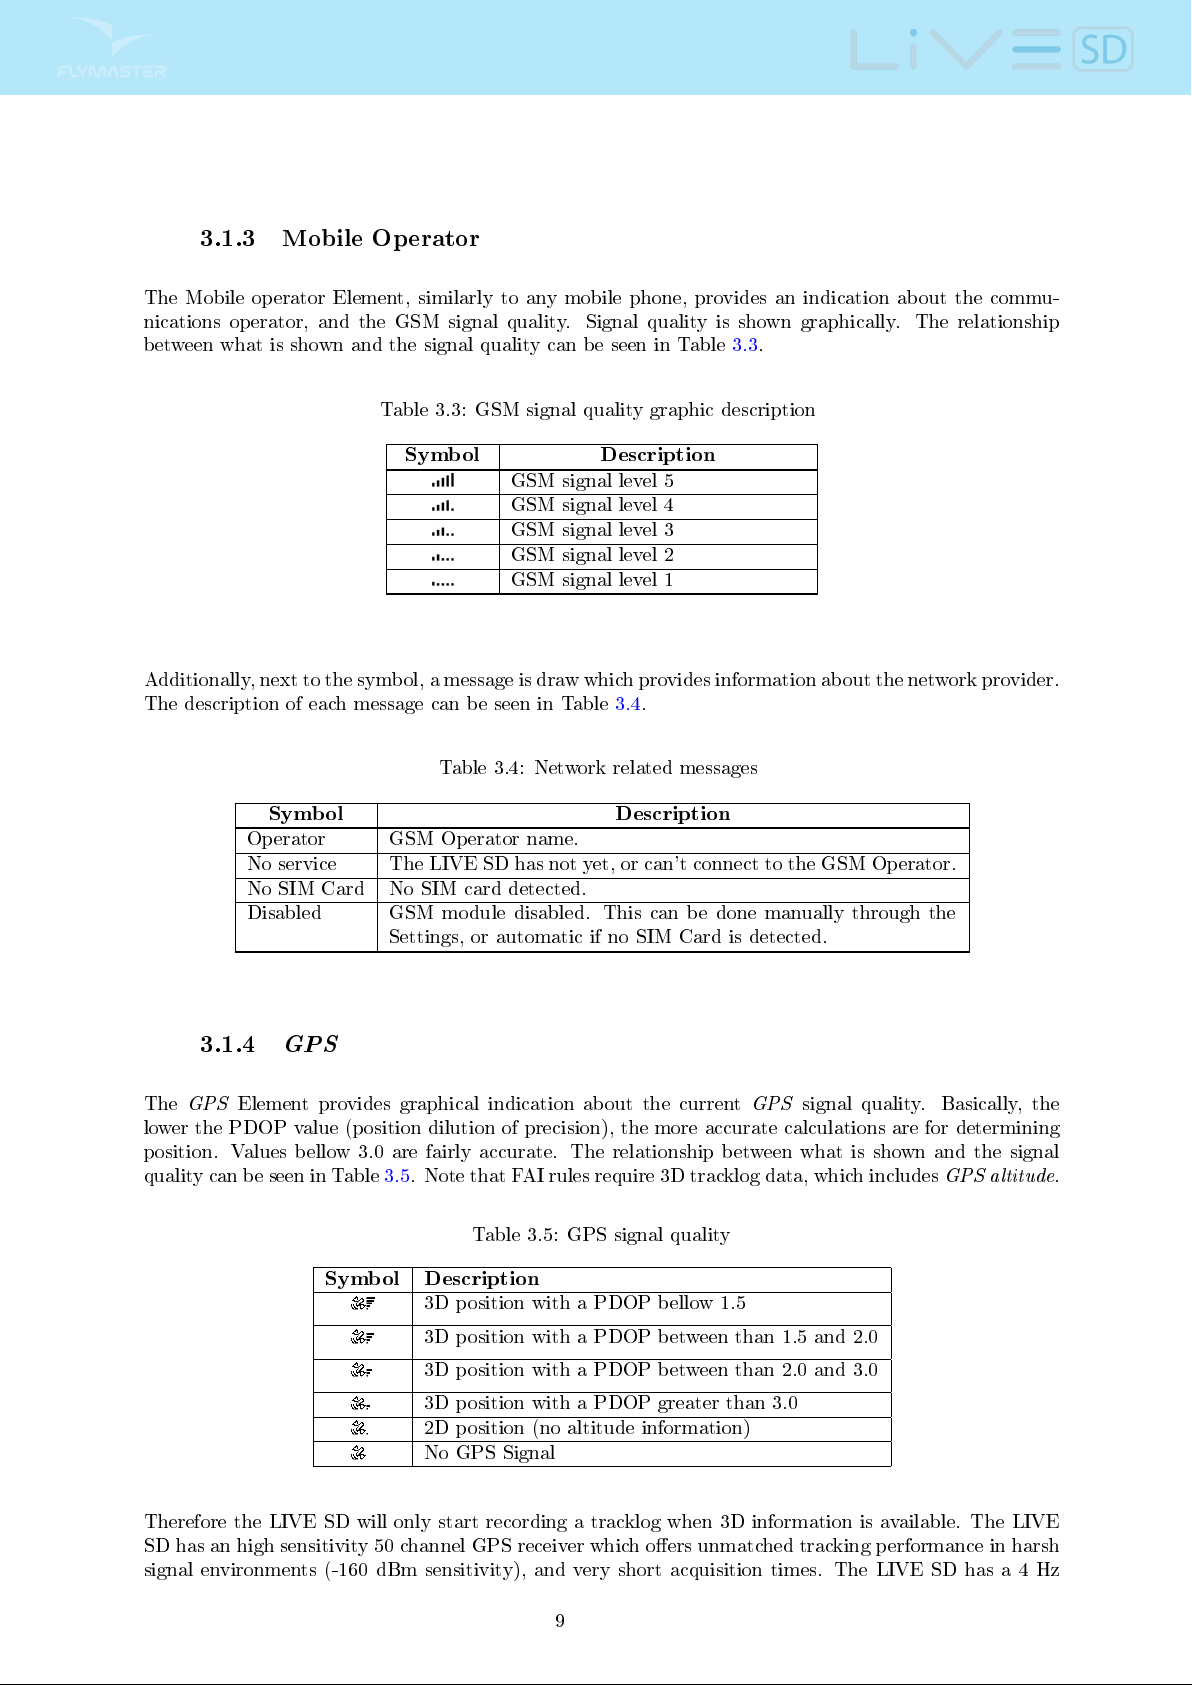
nications operator, and the GSM signal quality. Signal quality is shown graphically. The relationship
between what is shown and the signal quality can be seen in Table 3.3.
Table 3.3: GSM signal quality graphic description
Symbol Description
GSM signal level 5
GSM signal level 4
GSM signal level 3
GSM signal level 2
GSM signal level 1
Additionally, next to the symbol, a message is draw which provides information about the network provider.
The description of each message can be seen in Table 3.4.
Table 3.4: Network related messages
Symbol Description
Operator GSM Operator name.
No service The LIVE SD has not yet, or can't connect to the GSM Operator.
No SIM Card No SIM card detected.
Disabled GSM module disabled. This can be done manually through the
Settings, or automatic if no SIM Card is detected.
3.1.4
The
GPS
lower the PDOP value (position dilution of precision), the more accurate calculations are for determining
position. Values bellow 3.0 are fairly accurate. The relationship between what is shown and the signal
quality can be seen in Table 3.5. Note that FAI rules require 3D tracklog data, which includes
Therefore the LIVE SD will only start recording a tracklog when 3D information is available. The LIVE
SD has an high sensitivity 50 channel GPS receiver which oers unmatched tracking performance in harsh
signal environments (-160 dBm sensitivity), and very short acquisition times. The LIVE SD has a 4 Hz
GPS
Element provides graphical indication about the current
Table 3.5: GPS signal quality
Symbol Description
3D position with a PDOP bellow 1.5
3D position with a PDOP between than 1.5 and 2.0
3D position with a PDOP between than 2.0 and 3.0
3D position with a PDOP greater than 3.0
2D position (no altitude information)
No GPS Signal
9
GPS
signal quality. Basically, the
GPS altitude
.
Page 11
GPS update rate (most of others only provide 1Hz) which allows the LIVE SD pilot to see very small speed
and position changes. Furthermore, the movement of the direction arrow is smoother and any position
change is shown in a quarter of the time of other devices. Note that the 4 Hz update rate requires more than
5 satellites in view. More information about
seen in (
http://en.wikipedia.org/wiki/Error_analysis_for_the_Global_Positioning_System
GPS
accuracy and also other
GPS
related information can be
).
3.1.5 Vario
The Analog Vario Elements shows information regarding the analogue instantaneous vertical speed. There
are four dierent Elements that can be used to display the vario. All of these element can be resized and
re-positioned.
Analog Vario
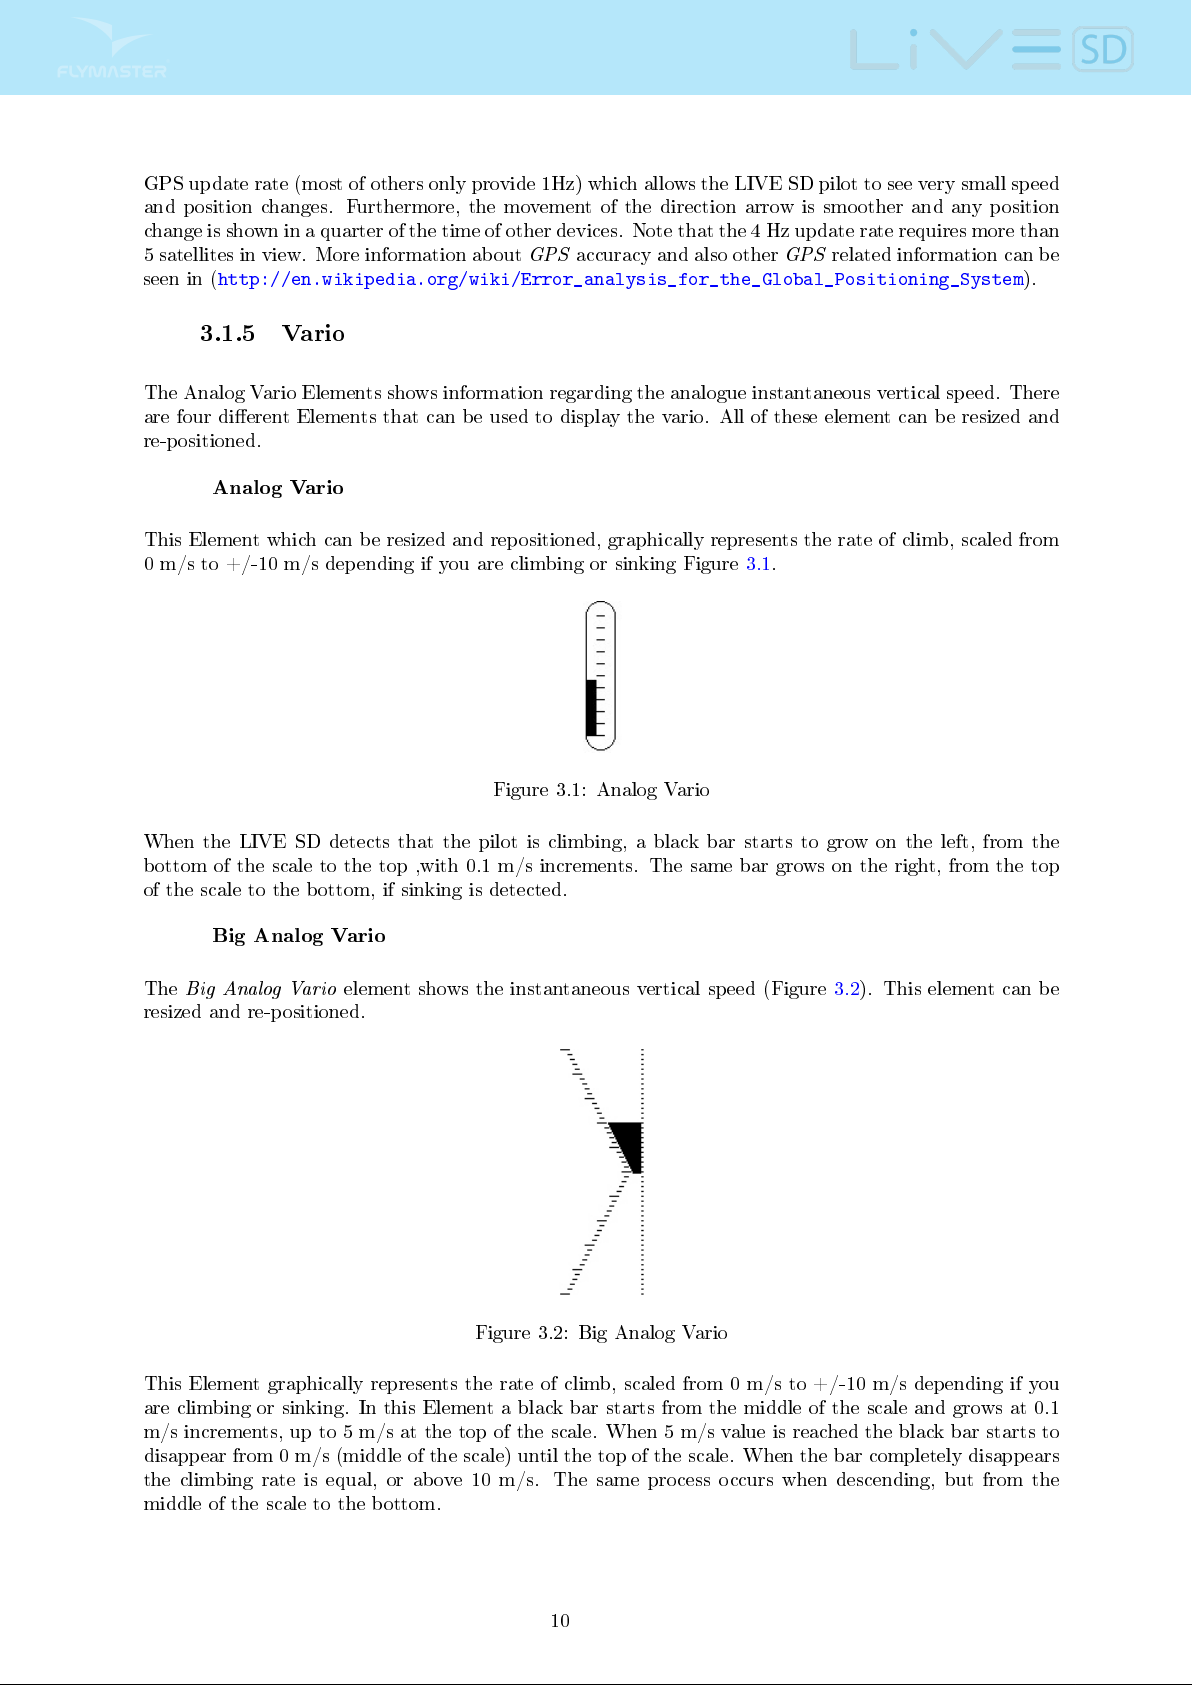
This Element which can be resized and repositioned, graphically represents the rate of climb, scaled from
0 m/s to +/-10 m/s depending if you are climbing or sinking Figure 3.1.
Figure 3.1: Analog Vario
When the LIVE SD detects that the pilot is climbing, a black bar starts to grow on the left, from the
bottom of the scale to the top ,with 0.1 m/s increments. The same bar grows on the right, from the top
of the scale to the bottom, if sinking is detected.
Big Analog Vario
The
Big Analog Vario
resized and re-positioned.
element shows the instantaneous vertical speed (Figure 3.2). This element can be
Figure 3.2: Big Analog Vario
This Element graphically represents the rate of climb, scaled from 0 m/s to +/-10 m/s depending if you
are climbing or sinking. In this Element a black bar starts from the middle of the scale and grows at 0.1
m/s increments, up to 5 m/s at the top of the scale. When 5 m/s value is reached the black bar starts to
disappear from 0 m/s (middle of the scale) until the top of the scale. When the bar completely disappears
the climbing rate is equal, or above 10 m/s. The same process occurs when descending, but from the
middle of the scale to the bottom.
10
Page 12
Double Bar Analog Vario and McCready Indicator
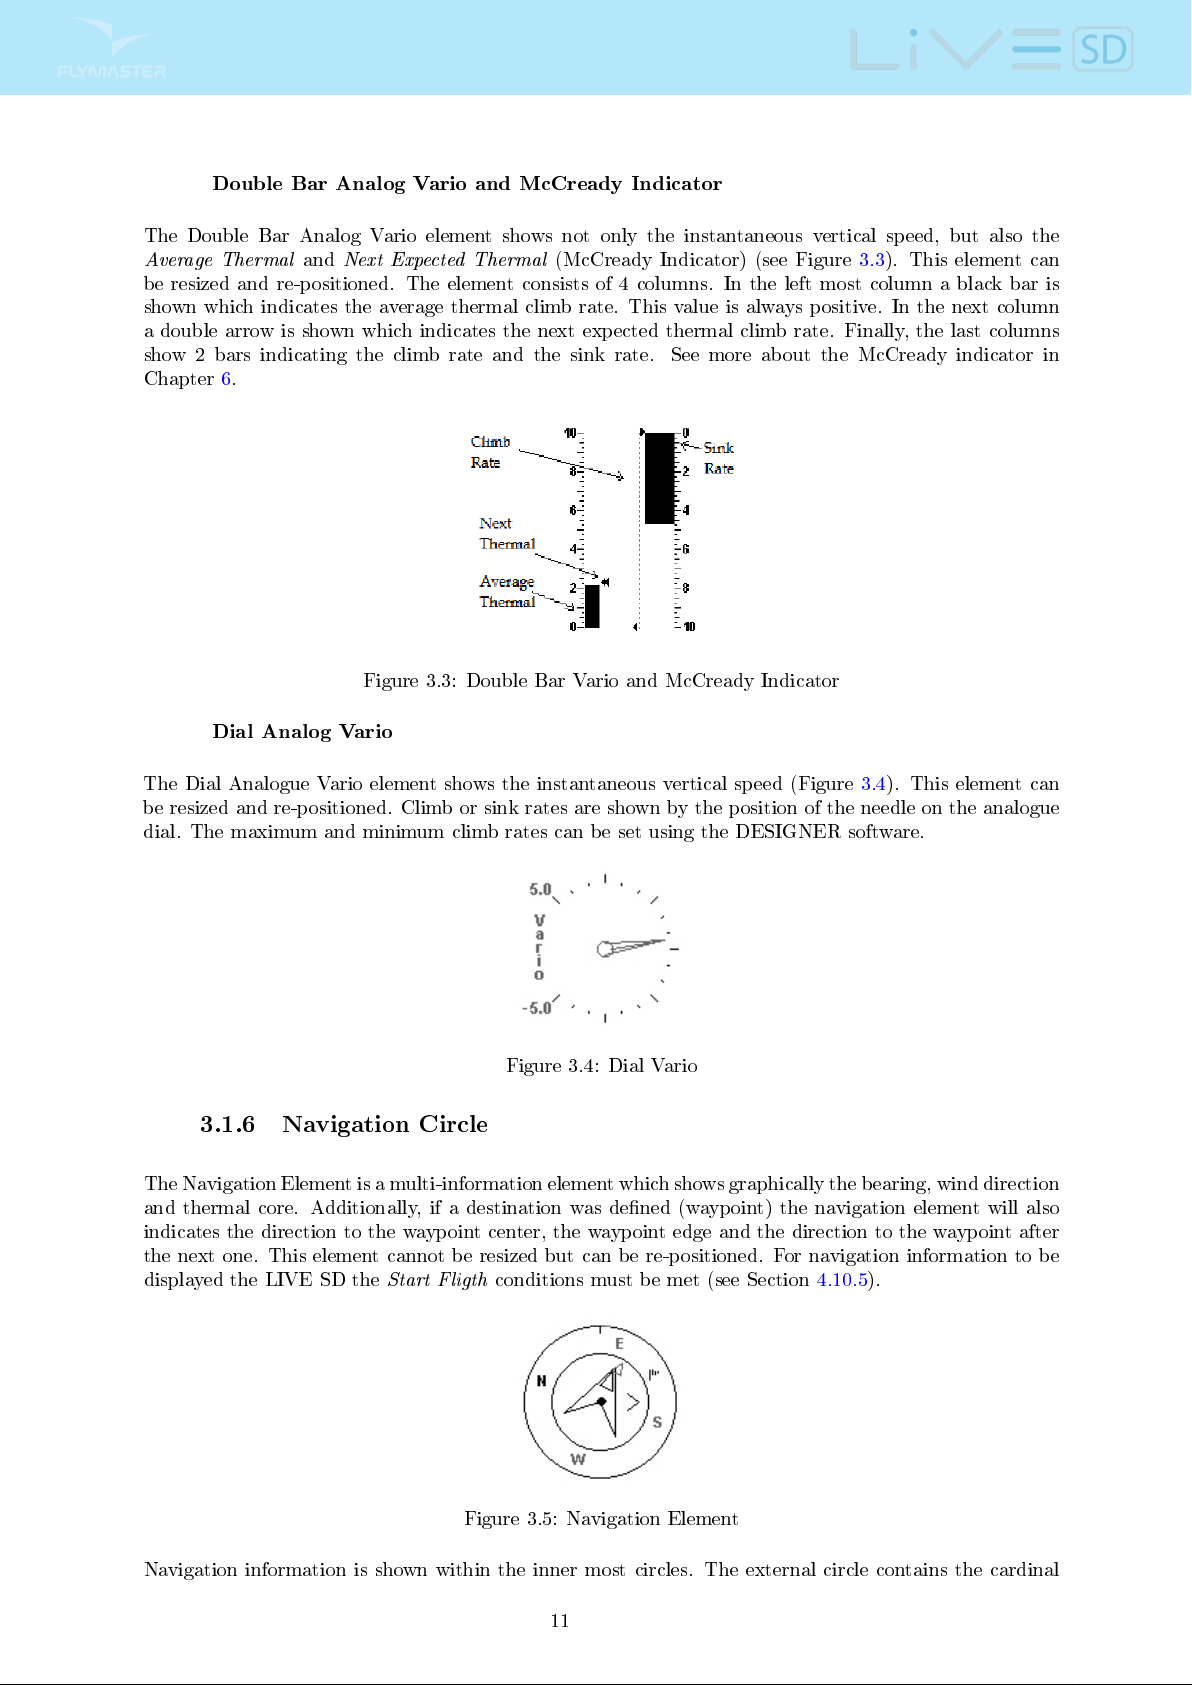
The Double Bar Analog Vario element shows not only the instantaneous vertical speed, but also the
Average Thermal
be resized and re-positioned. The element consists of 4 columns. In the left most column a black bar is
shown which indicates the average thermal climb rate. This value is always positive. In the next column
a double arrow is shown which indicates the next expected thermal climb rate. Finally, the last columns
show 2 bars indicating the climb rate and the sink rate. See more about the McCready indicator in
Chapter 6.
Dial Analog Vario
and
Next Expected Thermal
Figure 3.3: Double Bar Vario and McCready Indicator
(McCready Indicator) (see Figure 3.3). This element can
The Dial Analogue Vario element shows the instantaneous vertical speed (Figure 3.4). This element can
be resized and re-positioned. Climb or sink rates are shown by the position of the needle on the analogue
dial. The maximum and minimum climb rates can be set using the DESIGNER software.
Figure 3.4: Dial Vario
3.1.6 Navigation Circle
The Navigation Element is a multi-information element which shows graphically the bearing, wind direction
and thermal core. Additionally, if a destination was dened (waypoint) the navigation element will also
indicates the direction to the waypoint center, the waypoint edge and the direction to the waypoint after
the next one. This element cannot be resized but can be re-positioned. For navigation information to be
displayed the LIVE SD the
Start Fligth
conditions must be met (see Section 4.10.5).
Figure 3.5: Navigation Element
Navigation information is shown within the inner most circles. The external circle contains the cardinal
11
Page 13
points and the Wind Flag. The current traveling direction (bearing) corresponds to the point indicated in
the top of the navigation circle. On the example shown in Figure 3.5, the bearing is approximately 80º.
Navigation Arrows
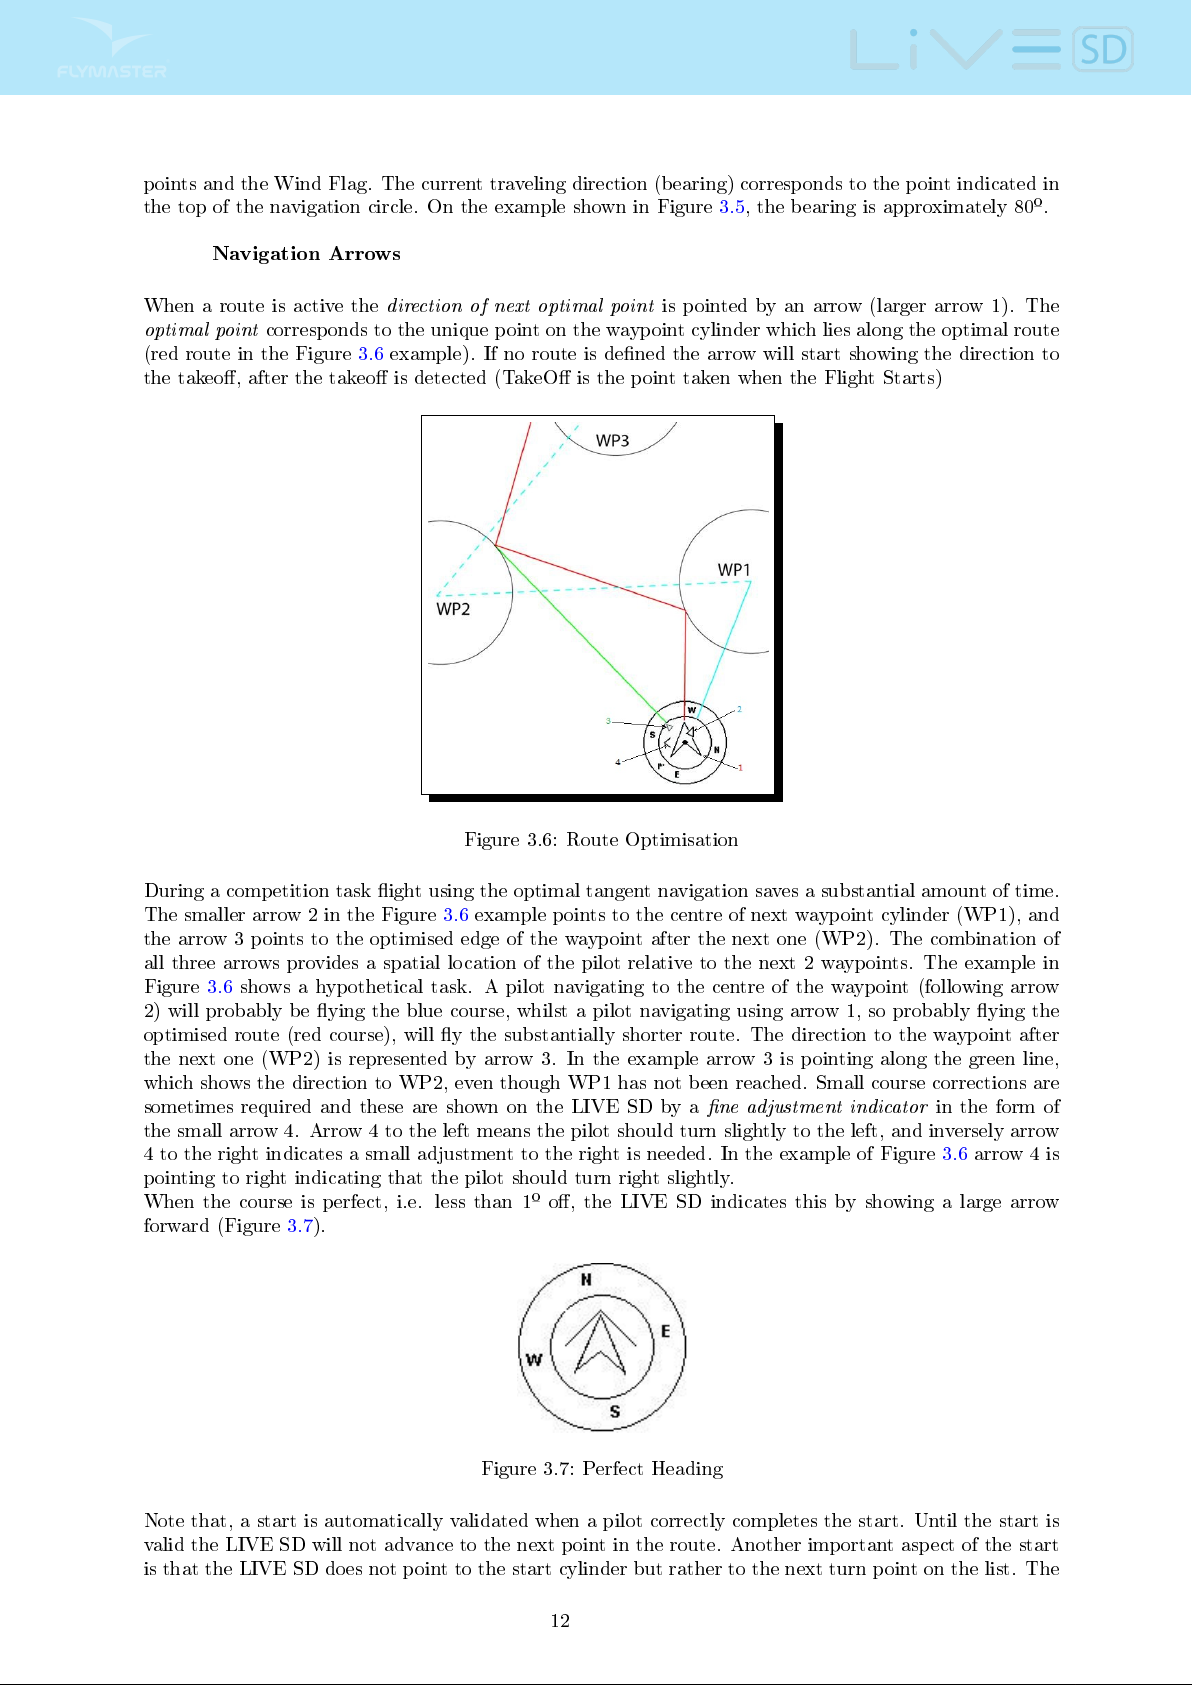
When a route is active the
optimal point
corresponds to the unique point on the waypoint cylinder which lies along the optimal route
direction of next optimal point
is pointed by an arrow (larger arrow 1). The
(red route in the Figure 3.6 example). If no route is dened the arrow will start showing the direction to
the takeo, after the takeo is detected (TakeO is the point taken when the Flight Starts)
Figure 3.6: Route Optimisation
During a competition task ight using the optimal tangent navigation saves a substantial amount of time.
The smaller arrow 2 in the Figure 3.6 example points to the centre of next waypoint cylinder (WP1), and
the arrow 3 points to the optimised edge of the waypoint after the next one (WP2). The combination of
all three arrows provides a spatial location of the pilot relative to the next 2 waypoints. The example in
Figure 3.6 shows a hypothetical task. A pilot navigating to the centre of the waypoint (following arrow
2) will probably be ying the blue course, whilst a pilot navigating using arrow 1, so probably ying the
optimised route (red course), will y the substantially shorter route. The direction to the waypoint after
the next one (WP2) is represented by arrow 3. In the example arrow 3 is pointing along the green line,
which shows the direction to WP2, even though WP1 has not been reached. Small course corrections are
sometimes required and these are shown on the LIVE SD by a
ne adjustment indicator
in the form of
the small arrow 4. Arrow 4 to the left means the pilot should turn slightly to the left, and inversely arrow
4 to the right indicates a small adjustment to the right is needed. In the example of Figure 3.6 arrow 4 is
pointing to right indicating that the pilot should turn right slightly.
When the course is perfect, i.e. less than 1ºo, the LIVE SD indicates this by showing a large arrow
forward (Figure 3.7).
Figure 3.7: Perfect Heading
Note that, a start is automatically validated when a pilot correctly completes the start. Until the start is
valid the LIVE SD will not advance to the next point in the route. Another important aspect of the start
is that the LIVE SD does not point to the start cylinder but rather to the next turn point on the list. The
12
Page 14
distance to the start will become highlighted when the pilot is in an irregular position, i.e. inside a start
cylinder where he should be out or vice-versa.
Thermal Core Map
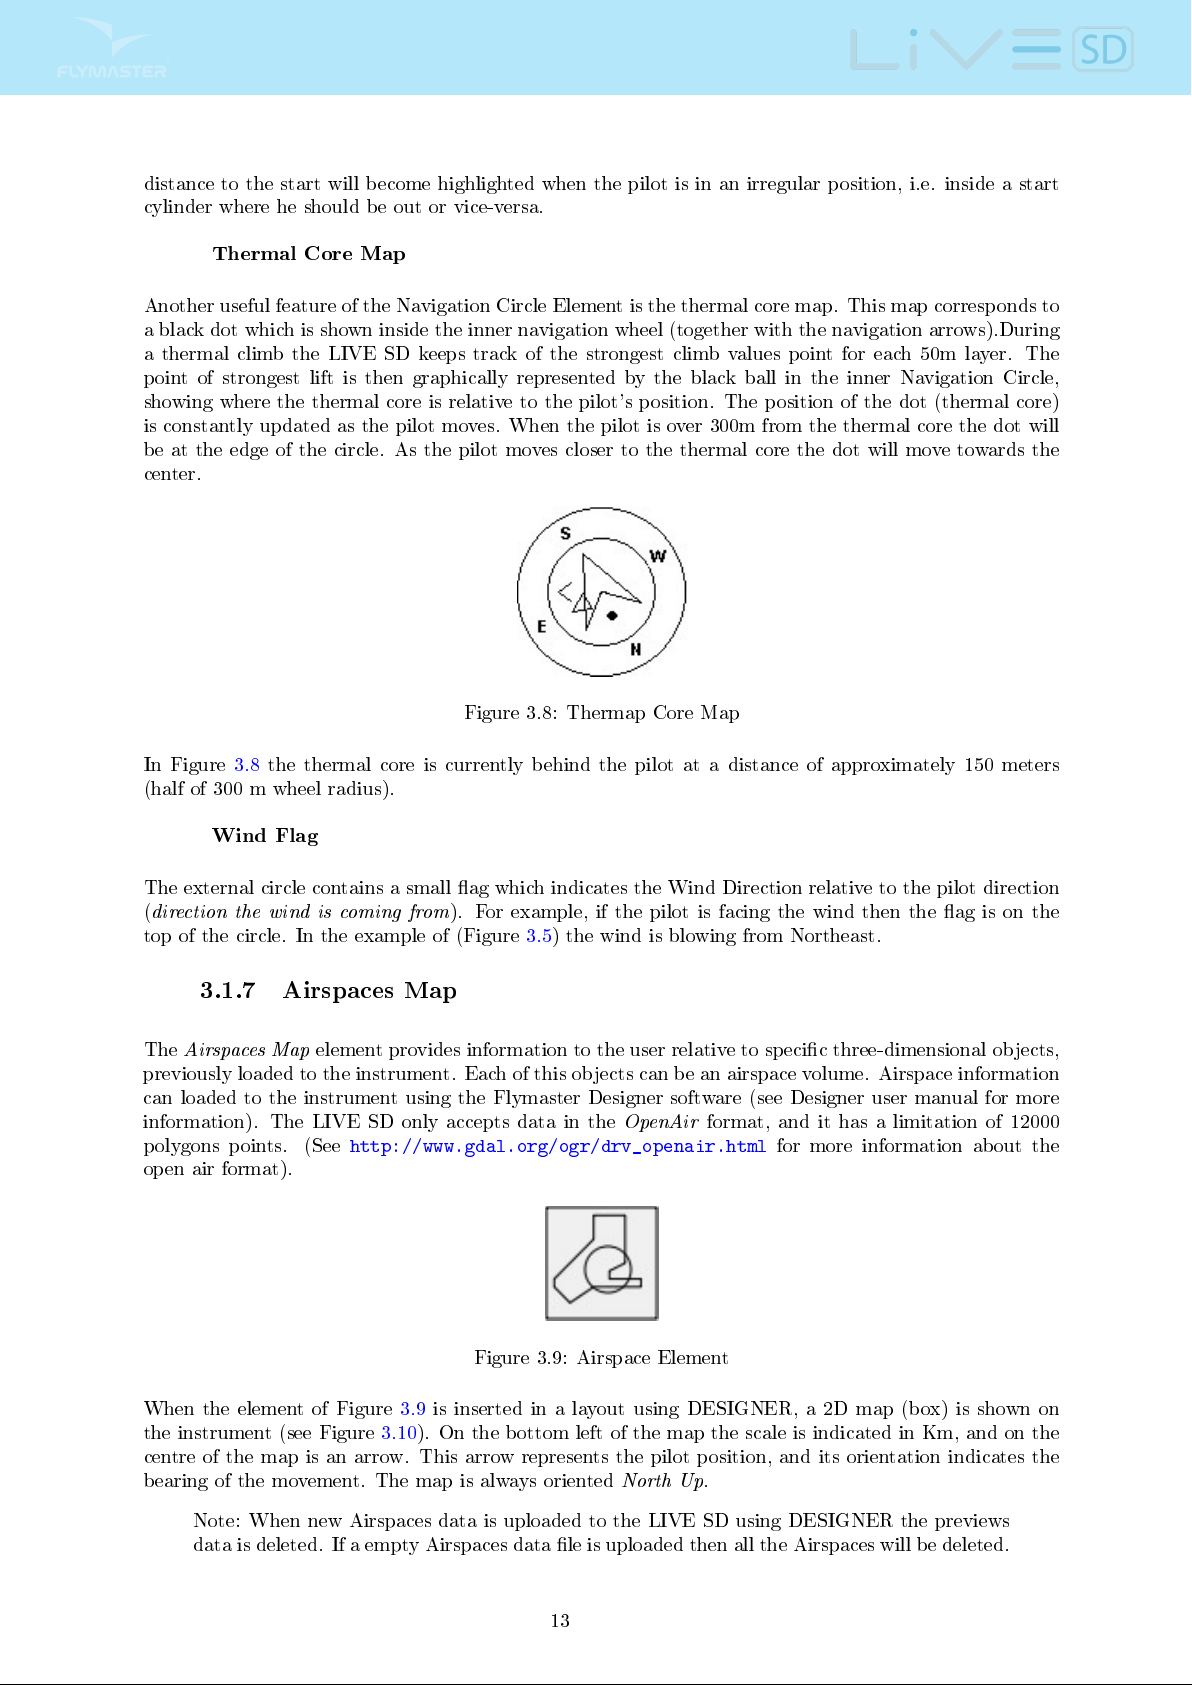
Another useful feature of the Navigation Circle Element is the thermal core map. This map corresponds to
a black dot which is shown inside the inner navigation wheel (together with the navigation arrows).During
a thermal climb the LIVE SD keeps track of the strongest climb values point for each 50m layer. The
point of strongest lift is then graphically represented by the black ball in the inner Navigation Circle,
showing where the thermal core is relative to the pilot's position. The position of the dot (thermal core)
is constantly updated as the pilot moves. When the pilot is over 300m from the thermal core the dot will
be at the edge of the circle. As the pilot moves closer to the thermal core the dot will move towards the
center.
Figure 3.8: Thermap Core Map
In Figure 3.8 the thermal core is currently behind the pilot at a distance of approximately 150 meters
(half of 300 m wheel radius).
Wind Flag
The external circle contains a small ag which indicates the Wind Direction relative to the pilot direction
(
direction the wind is coming from
top of the circle. In the example of (Figure 3.5) the wind is blowing from Northeast.
). For example, if the pilot is facing the wind then the ag is on the
3.1.7 Airspaces Map
The
Airspaces Map
previously loaded to the instrument. Each of this objects can be an airspace volume. Airspace information
can loaded to the instrument using the Flymaster Designer software (see Designer user manual for more
information). The LIVE SD only accepts data in the
polygons points. (See
open air format).
element provides information to the user relative to specic three-dimensional objects,
OpenAir
http://www.gdal.org/ogr/drv_openair.html
format, and it has a limitation of 12000
for more information about the
Figure 3.9: Airspace Element
When the element of Figure 3.9 is inserted in a layout using DESIGNER, a 2D map (box) is shown on
the instrument (see Figure 3.10). On the bottom left of the map the scale is indicated in Km, and on the
centre of the map is an arrow. This arrow represents the pilot position, and its orientation indicates the
bearing of the movement. The map is always oriented
Note: When new Airspaces data is uploaded to the LIVE SD using DESIGNER the previews
data is deleted. If a empty Airspaces data le is uploaded then all the Airspaces will be deleted.
13
North Up
.
Page 15
The rst time the map is drawn, it is centred on the last GPS position the LIVE SD has in its memory.
The map is re-centred once the ight starts i.e. when a valid gps signal exists, and the
Section 4.10.5) is reached.
Note: After new Airspace data is uploaded to the LIVE SD it can only be seen on the Map
after the
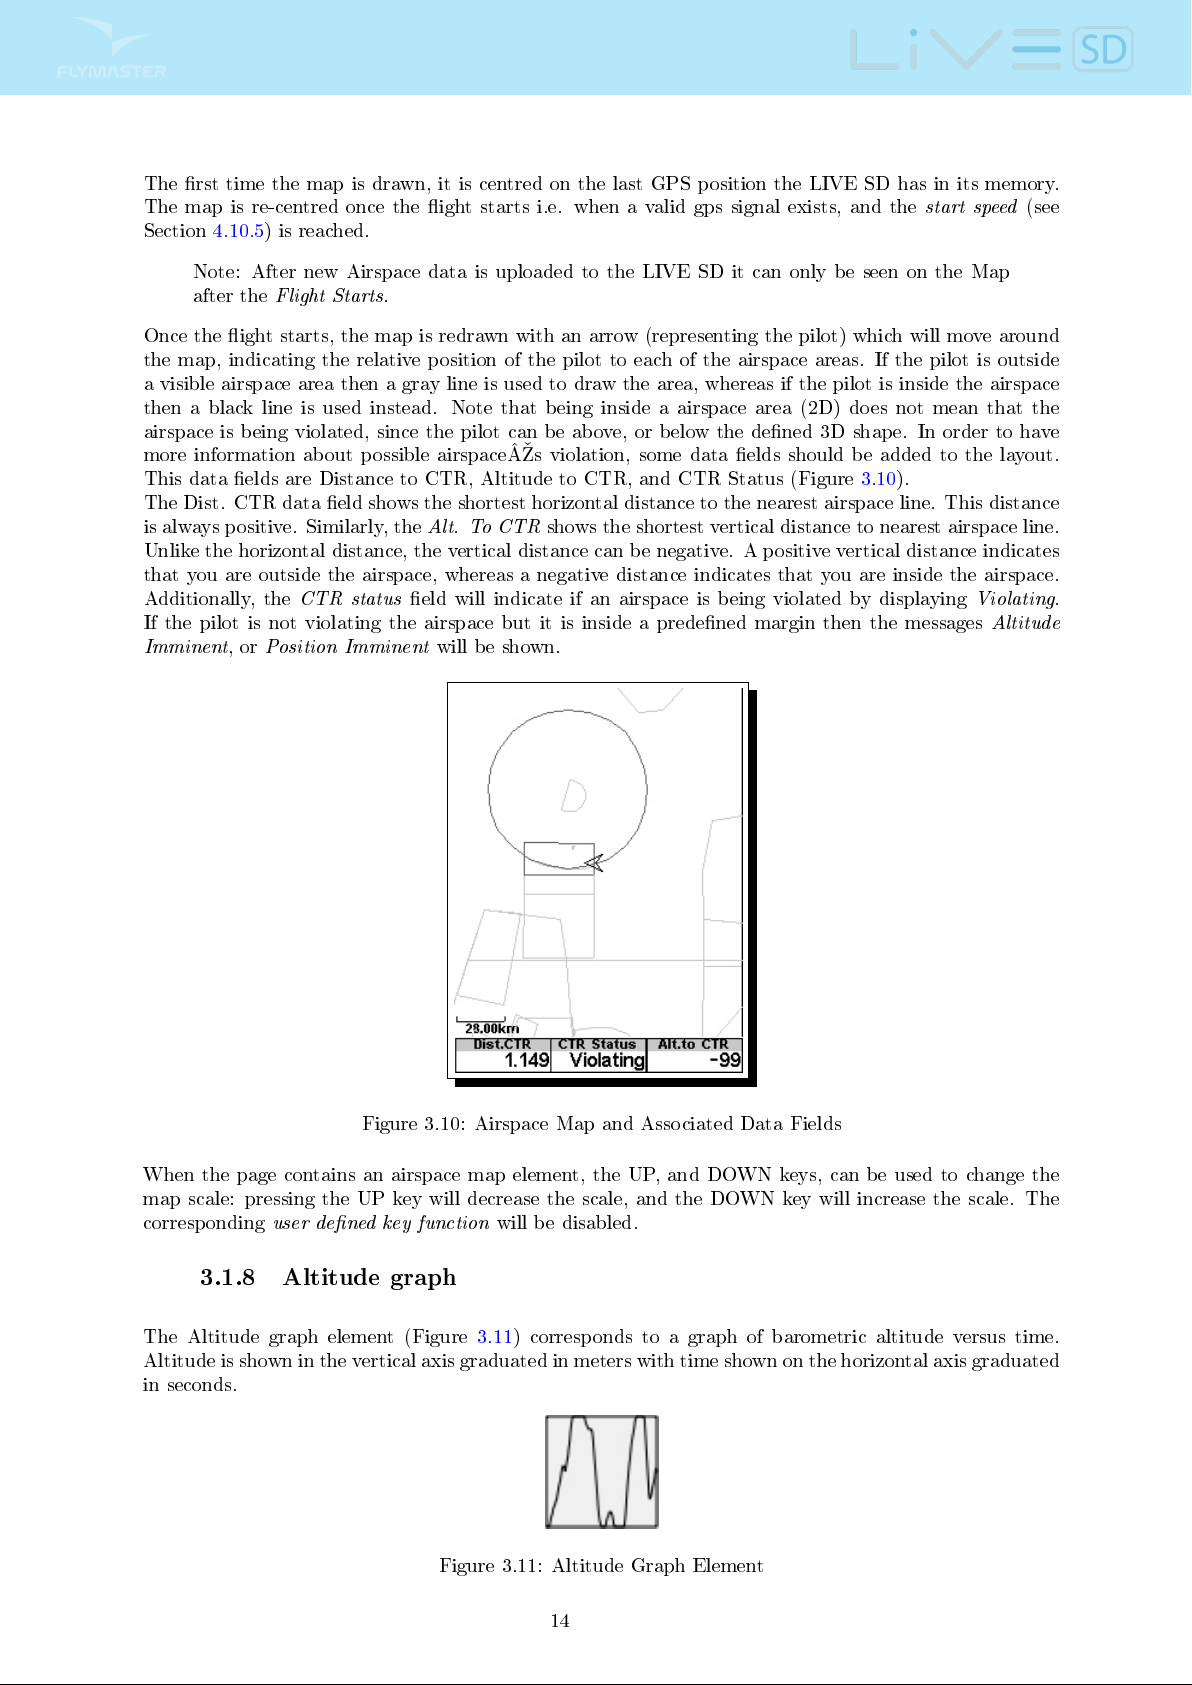
Once the ight starts, the map is redrawn with an arrow (representing the pilot) which will move around
the map, indicating the relative position of the pilot to each of the airspace areas. If the pilot is outside
a visible airspace area then a gray line is used to draw the area, whereas if the pilot is inside the airspace
then a black line is used instead. Note that being inside a airspace area (2D) does not mean that the
airspace is being violated, since the pilot can be above, or below the dened 3D shape. In order to have
more information about possible airspaceÂs violation, some data elds should be added to the layout.
This data elds are Distance to CTR, Altitude to CTR, and CTR Status (Figure 3.10).
The Dist. CTR data eld shows the shortest horizontal distance to the nearest airspace line. This distance
is always positive. Similarly, the
Unlike the horizontal distance, the vertical distance can be negative. A positive vertical distance indicates
that you are outside the airspace, whereas a negative distance indicates that you are inside the airspace.
Additionally, the
If the pilot is not violating the airspace but it is inside a predened margin then the messages
Imminent
Flight Starts
CTR status
, or
Position Imminent
.
Alt. To CTR
eld will indicate if an airspace is being violated by displaying
will be shown.
shows the shortest vertical distance to nearest airspace line.
start speed
Violating
Altitude
(see
.
Figure 3.10: Airspace Map and Associated Data Fields
When the page contains an airspace map element, the UP, and DOWN keys, can be used to change the
map scale: pressing the UP key will decrease the scale, and the DOWN key will increase the scale. The
corresponding
user dened key function
will be disabled.
3.1.8 Altitude graph
The Altitude graph element (Figure 3.11) corresponds to a graph of barometric altitude versus time.
Altitude is shown in the vertical axis graduated in meters with time shown on the horizontal axis graduated
in seconds.
Figure 3.11: Altitude Graph Element
14
Page 16
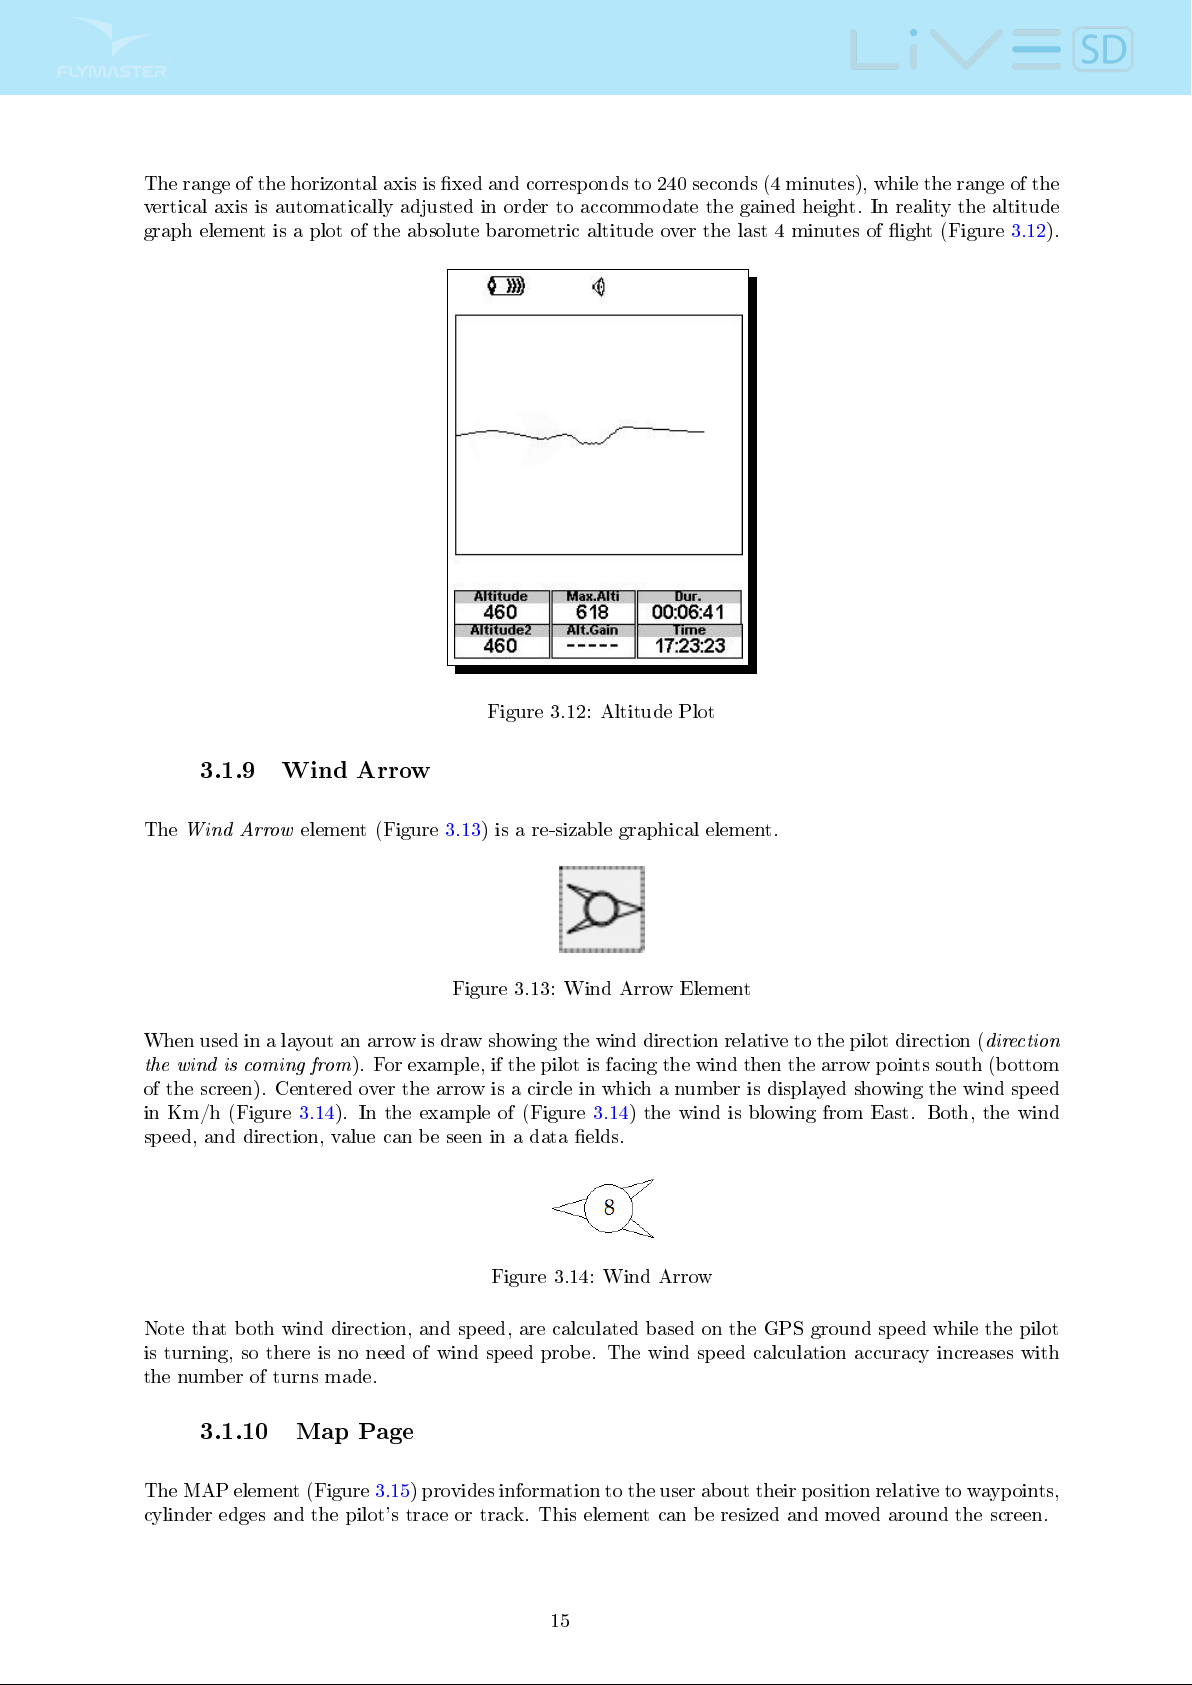
The range of the horizontal axis is xed and corresponds to 240 seconds (4 minutes), while the range of the
vertical axis is automatically adjusted in order to accommodate the gained height. In reality the altitude
graph element is a plot of the absolute barometric altitude over the last 4 minutes of ight (Figure 3.12).
Figure 3.12: Altitude Plot
3.1.9 Wind Arrow
The
Wind Arrow
When used in a layout an arrow is draw showing the wind direction relative to the pilot direction (
the wind is coming from
of the screen). Centered over the arrow is a circle in which a number is displayed showing the wind speed
in Km/h (Figure 3.14). In the example of (Figure 3.14) the wind is blowing from East. Both, the wind
speed, and direction, value can be seen in a data elds.
Note that both wind direction, and speed, are calculated based on the GPS ground speed while the pilot
is turning, so there is no need of wind speed probe. The wind speed calculation accuracy increases with
the number of turns made.
element (Figure 3.13) is a re-sizable graphical element.
Figure 3.13: Wind Arrow Element
direction
). For example, if the pilot is facing the wind then the arrow points south (bottom
Figure 3.14: Wind Arrow
3.1.10 Map Page
The MAP element (Figure 3.15) provides information to the user about their position relative to waypoints,
cylinder edges and the pilot's trace or track. This element can be resized and moved around the screen.
15
Page 17
Figure 3.15: Map Element
A typical map page in ight may look like Figure. 20. In this gure is shown the scale on the bottom left.
The scale can be manually changed by pressing the F1 button to enlarge the map and therefore reduce
the scale, and conversely by pressing the F2 button to reduce the map and therefore increase the scale.
Figure 3.16: Map Page
If ying a competition route, the optimized route is drawn between the turnpoint cylinders. The position
of the pilot is indicated by the arrow and the trace for the last approximately 4 mins of the ight is shown.
Traces older than 4 mins are erased to reduce clutter on the screen.
Figure 3.17: Compass Element
3.1.11 Compass
The Compass element (Figure 3.17) show all the data provided by the LIVE SD built in magnetic compass.
This element can be resized and moved around the screen. The compass includes an arrow which is always
alined with the LIVE SD . If the LIVE SD is turned the cardinal points will also turn in order the arrow
tip points the right cardinal point.
Figure 3.18: Compass example
In the example of Figure 3.18 the LIVE SD is pointing almost to East. The direction is represented by
the arrow, and also indicated numerical (76°degrees).
16
Page 18
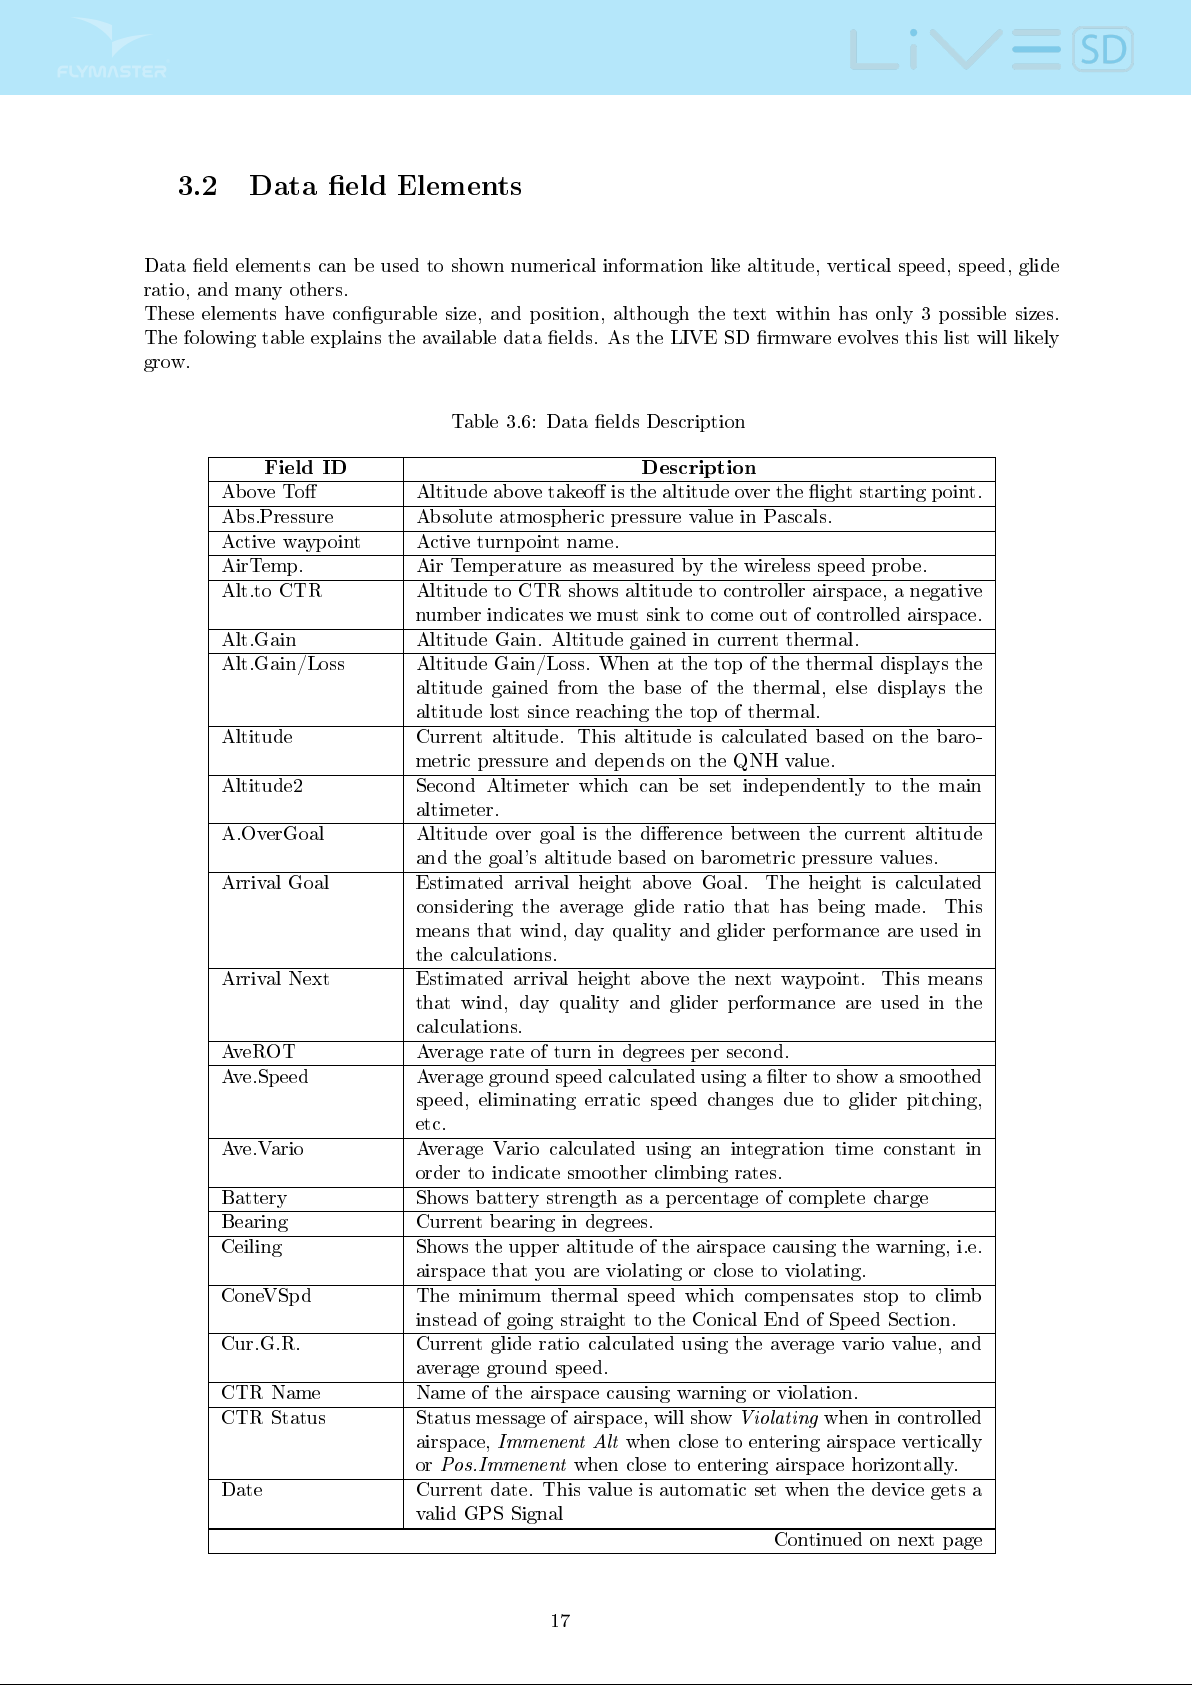
3.2 Data eld Elements
Data eld elements can be used to shown numerical information like altitude, vertical speed, speed, glide
ratio, and many others.
These elements have congurable size, and position, although the text within has only 3 possible sizes.
The folowing table explains the available data elds. As the LIVE SD rmware evolves this list will likely
grow.
Table 3.6: Data elds Description
Field ID Description
Above To Altitude above takeo is the altitude over the ight starting point.
Abs.Pressure Absolute atmospheric pressure value in Pascals.
Active waypoint Active turnpoint name.
AirTemp. Air Temperature as measured by the wireless speed probe.
Alt.to CTR Altitude to CTR shows altitude to controller airspace, a negative
number indicates we must sink to come out of controlled airspace.
Alt.Gain Altitude Gain. Altitude gained in current thermal.
Alt.Gain/Loss Altitude Gain/Loss. When at the top of the thermal displays the
altitude gained from the base of the thermal, else displays the
altitude lost since reaching the top of thermal.
Altitude Current altitude. This altitude is calculated based on the baro-
metric pressure and depends on the QNH value.
Altitude2 Second Altimeter which can be set independently to the main
altimeter.
A.OverGoal Altitude over goal is the dierence between the current altitude
and the goal's altitude based on barometric pressure values.
Arrival Goal Estimated arrival height above Goal. The height is calculated
considering the average glide ratio that has being made. This
means that wind, day quality and glider performance are used in
the calculations.
Arrival Next Estimated arrival height above the next waypoint. This means
that wind, day quality and glider performance are used in the
calculations.
AveROT Average rate of turn in degrees per second.
Ave.Speed Average ground speed calculated using a lter to show a smoothed
speed, eliminating erratic speed changes due to glider pitching,
etc.
Ave.Vario Average Vario calculated using an integration time constant in
order to indicate smoother climbing rates.
Battery Shows battery strength as a percentage of complete charge
Bearing Current bearing in degrees.
Ceiling Shows the upper altitude of the airspace causing the warning, i.e.
airspace that you are violating or close to violating.
ConeVSpd The minimum thermal speed which compensates stop to climb
instead of going straight to the Conical End of Speed Section.
Cur.G.R. Current glide ratio calculated using the average vario value, and
average ground speed.
CTR Name Name of the airspace causing warning or violation.
CTR Status Status message of airspace, will show
airspace,
or
Date Current date. This value is automatic set when the device gets a
valid GPS Signal
Immenent Alt
Pos.Immenent
when close to entering airspace vertically
when close to entering airspace horizontally.
Violating
when in controlled
Continued on next page
17
Page 19
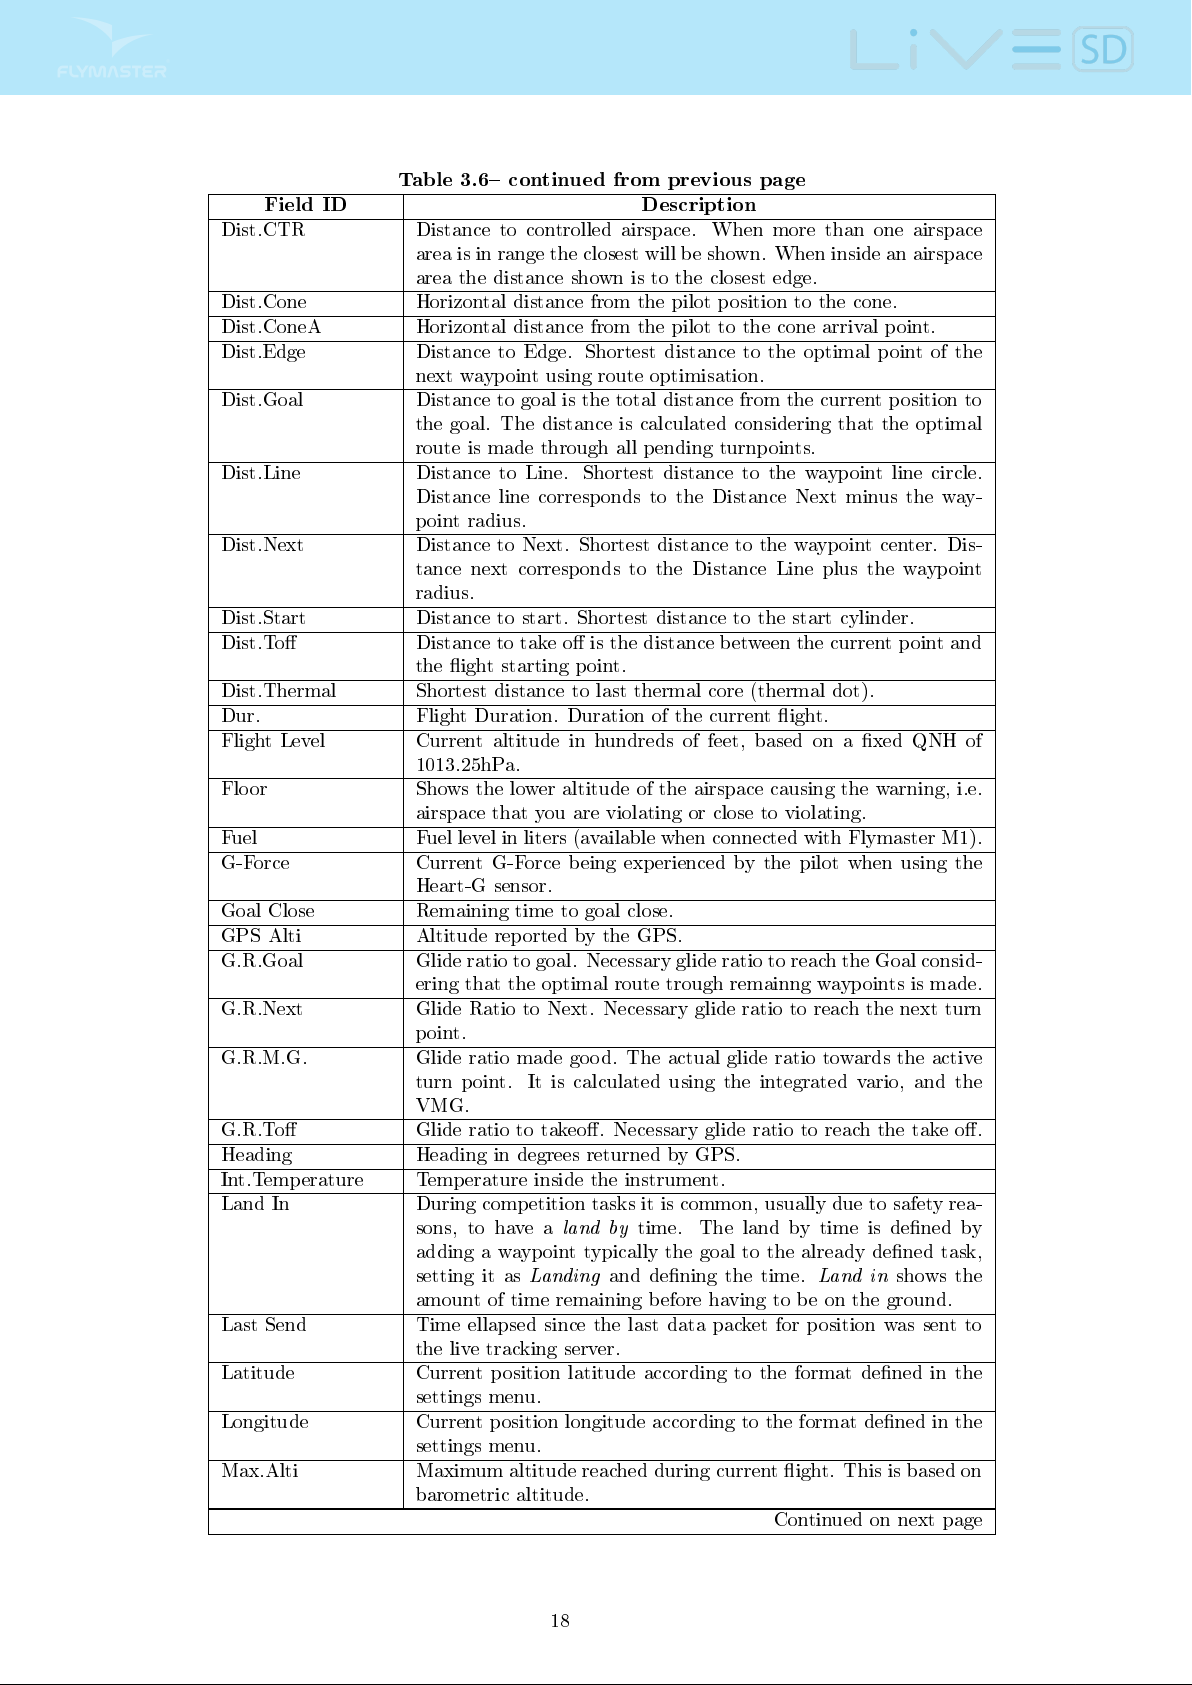
Table 3.6 continued from previous page
Field ID Description
Dist.CTR Distance to controlled airspace. When more than one airspace
area is in range the closest will be shown. When inside an airspace
area the distance shown is to the closest edge.
Dist.Cone Horizontal distance from the pilot position to the cone.
Dist.ConeA Horizontal distance from the pilot to the cone arrival point.
Dist.Edge Distance to Edge. Shortest distance to the optimal point of the
next waypoint using route optimisation.
Dist.Goal Distance to goal is the total distance from the current position to
the goal. The distance is calculated considering that the optimal
route is made through all pending turnpoints.
Dist.Line Distance to Line. Shortest distance to the waypoint line circle.
Distance line corresponds to the Distance Next minus the way-
point radius.
Dist.Next Distance to Next. Shortest distance to the waypoint center. Dis-
tance next corresponds to the Distance Line plus the waypoint
radius.
Dist.Start Distance to start. Shortest distance to the start cylinder.
Dist.To Distance to take o is the distance between the current point and
the ight starting point.
Dist.Thermal Shortest distance to last thermal core (thermal dot).
Dur. Flight Duration. Duration of the current ight.
Flight Level Current altitude in hundreds of feet, based on a xed QNH of
1013.25hPa.
Floor Shows the lower altitude of the airspace causing the warning, i.e.
airspace that you are violating or close to violating.
Fuel Fuel level in liters (available when connected with Flymaster M1).
G-Force Current G-Force being experienced by the pilot when using the
Heart-G sensor.
Goal Close Remaining time to goal close.
GPS Alti Altitude reported by the GPS.
G.R.Goal Glide ratio to goal. Necessary glide ratio to reach the Goal consid-
ering that the optimal route trough remainng waypoints is made.
G.R.Next Glide Ratio to Next. Necessary glide ratio to reach the next turn
point.
G.R.M.G. Glide ratio made good. The actual glide ratio towards the active
turn point. It is calculated using the integrated vario, and the
VMG.
G.R.To Glide ratio to takeo. Necessary glide ratio to reach the take o.
Heading Heading in degrees returned by GPS.
Int.Temperature Temperature inside the instrument.
Land In During competition tasks it is common, usually due to safety rea-
sons, to have a
land by
time. The land by time is dened by
adding a waypoint typically the goal to the already dened task,
setting it as
Landing
and dening the time.
Land in
shows the
amount of time remaining before having to be on the ground.
Last Send Time ellapsed since the last data packet for position was sent to
the live tracking server.
Latitude Current position latitude according to the format dened in the
settings menu.
Longitude Current position longitude according to the format dened in the
settings menu.
Max.Alti Maximum altitude reached during current ight. This is based on
barometric altitude.
Continued on next page
18
Page 20
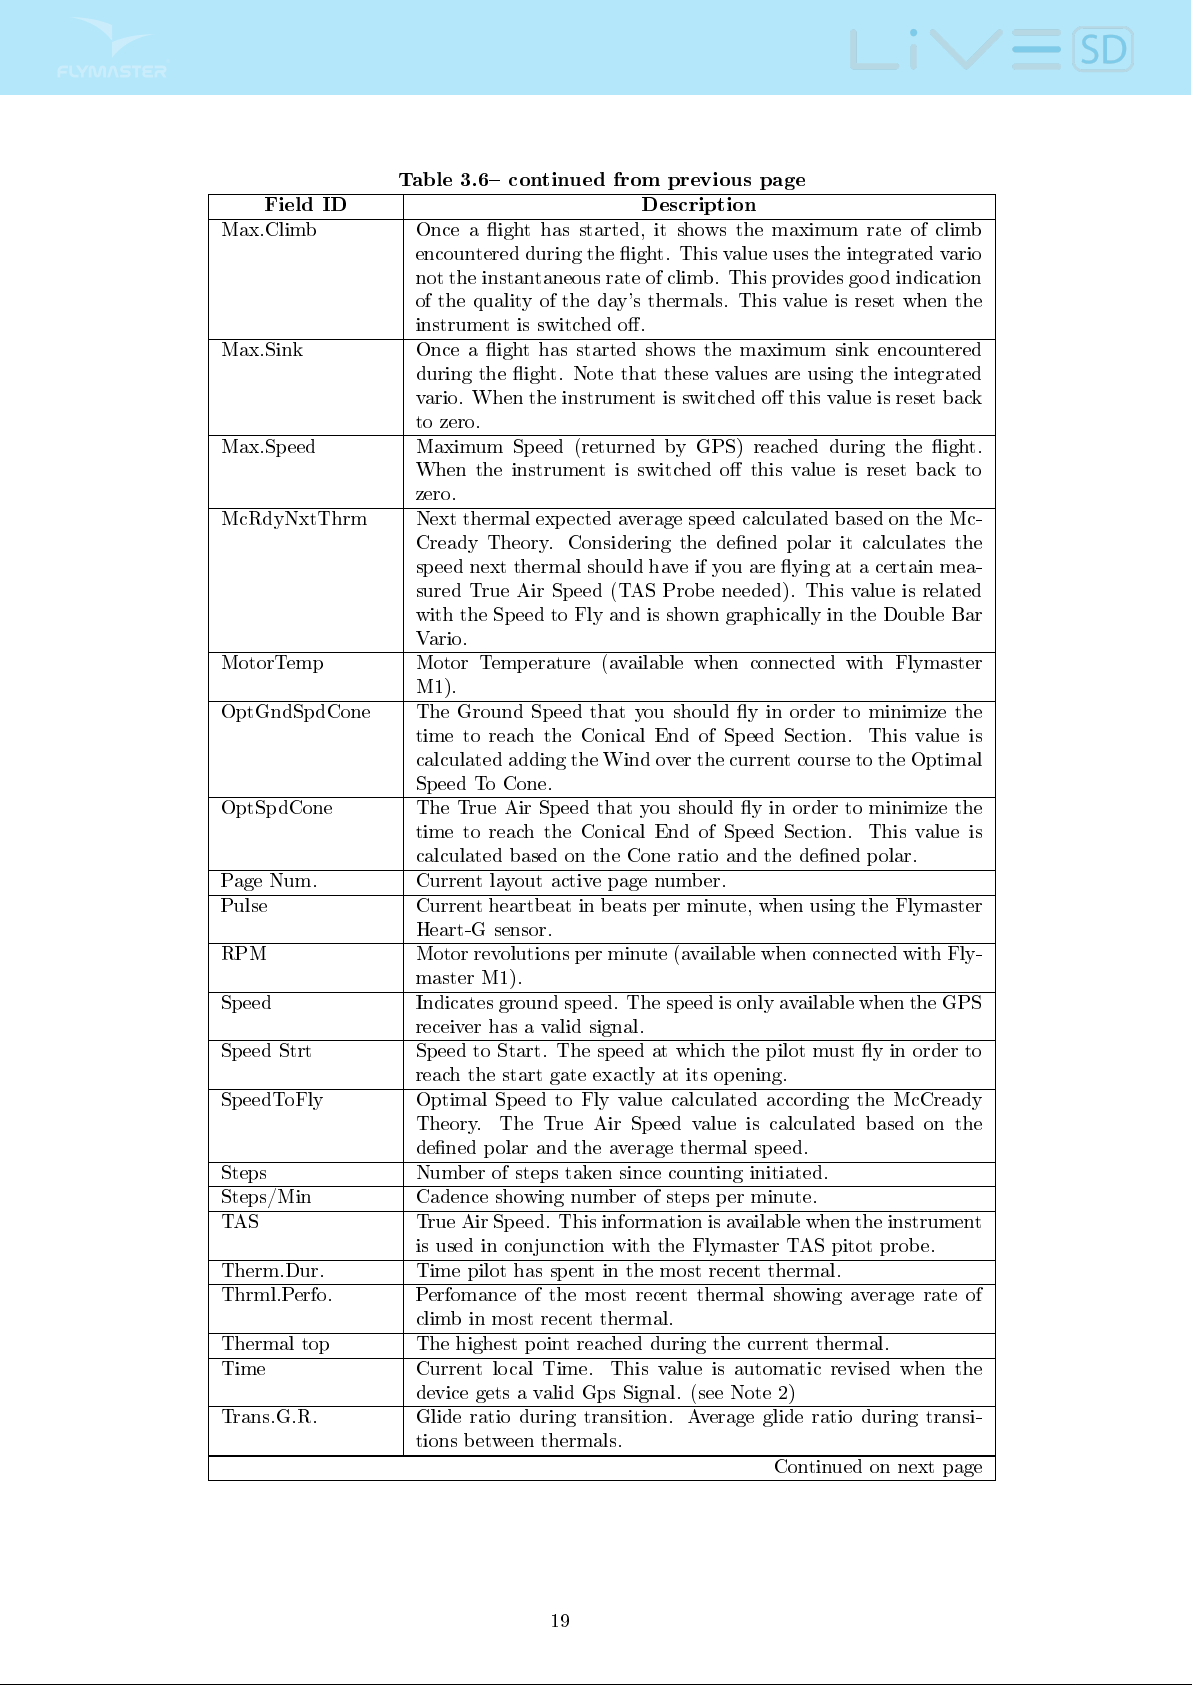
Table 3.6 continued from previous page
Field ID Description
Max.Climb Once a ight has started, it shows the maximum rate of climb
encountered during the ight. This value uses the integrated vario
not the instantaneous rate of climb. This provides good indication
of the quality of the day's thermals. This value is reset when the
instrument is switched o.
Max.Sink Once a ight has started shows the maximum sink encountered
during the ight. Note that these values are using the integrated
vario. When the instrument is switched o this value is reset back
to zero.
Max.Speed Maximum Speed (returned by GPS) reached during the ight.
When the instrument is switched o this value is reset back to
zero.
McRdyNxtThrm Next thermal expected average speed calculated based on the Mc-
Cready Theory. Considering the dened polar it calculates the
speed next thermal should have if you are ying at a certain mea-
sured True Air Speed (TAS Probe needed). This value is related
with the Speed to Fly and is shown graphically in the Double Bar
Vario.
MotorTemp Motor Temperature (available when connected with Flymaster
M1).
OptGndSpdCone The Ground Speed that you should y in order to minimize the
time to reach the Conical End of Speed Section. This value is
calculated adding the Wind over the current course to the Optimal
Speed To Cone.
OptSpdCone The True Air Speed that you should y in order to minimize the
time to reach the Conical End of Speed Section. This value is
calculated based on the Cone ratio and the dened polar.
Page Num. Current layout active page number.
Pulse Current heartbeat in beats per minute, when using the Flymaster
Heart-G sensor.
RPM Motor revolutions per minute (available when connected with Fly-
master M1).
Speed Indicates ground speed. The speed is only available when the GPS
receiver has a valid signal.
Speed Strt Speed to Start. The speed at which the pilot must y in order to
reach the start gate exactly at its opening.
SpeedToFly Optimal Speed to Fly value calculated according the McCready
Theory. The True Air Speed value is calculated based on the
dened polar and the average thermal speed.
Steps Number of steps taken since counting initiated.
Steps/Min Cadence showing number of steps per minute.
TAS True Air Speed. This information is available when the instrument
is used in conjunction with the Flymaster TAS pitot probe.
Therm.Dur. Time pilot has spent in the most recent thermal.
Thrml.Perfo. Perfomance of the most recent thermal showing average rate of
climb in most recent thermal.
Thermal top The highest point reached during the current thermal.
Time Current local Time. This value is automatic revised when the
device gets a valid Gps Signal. (see Note 2)
Trans.G.R. Glide ratio during transition. Average glide ratio during transi-
tions between thermals.
Continued on next page
19
Page 21
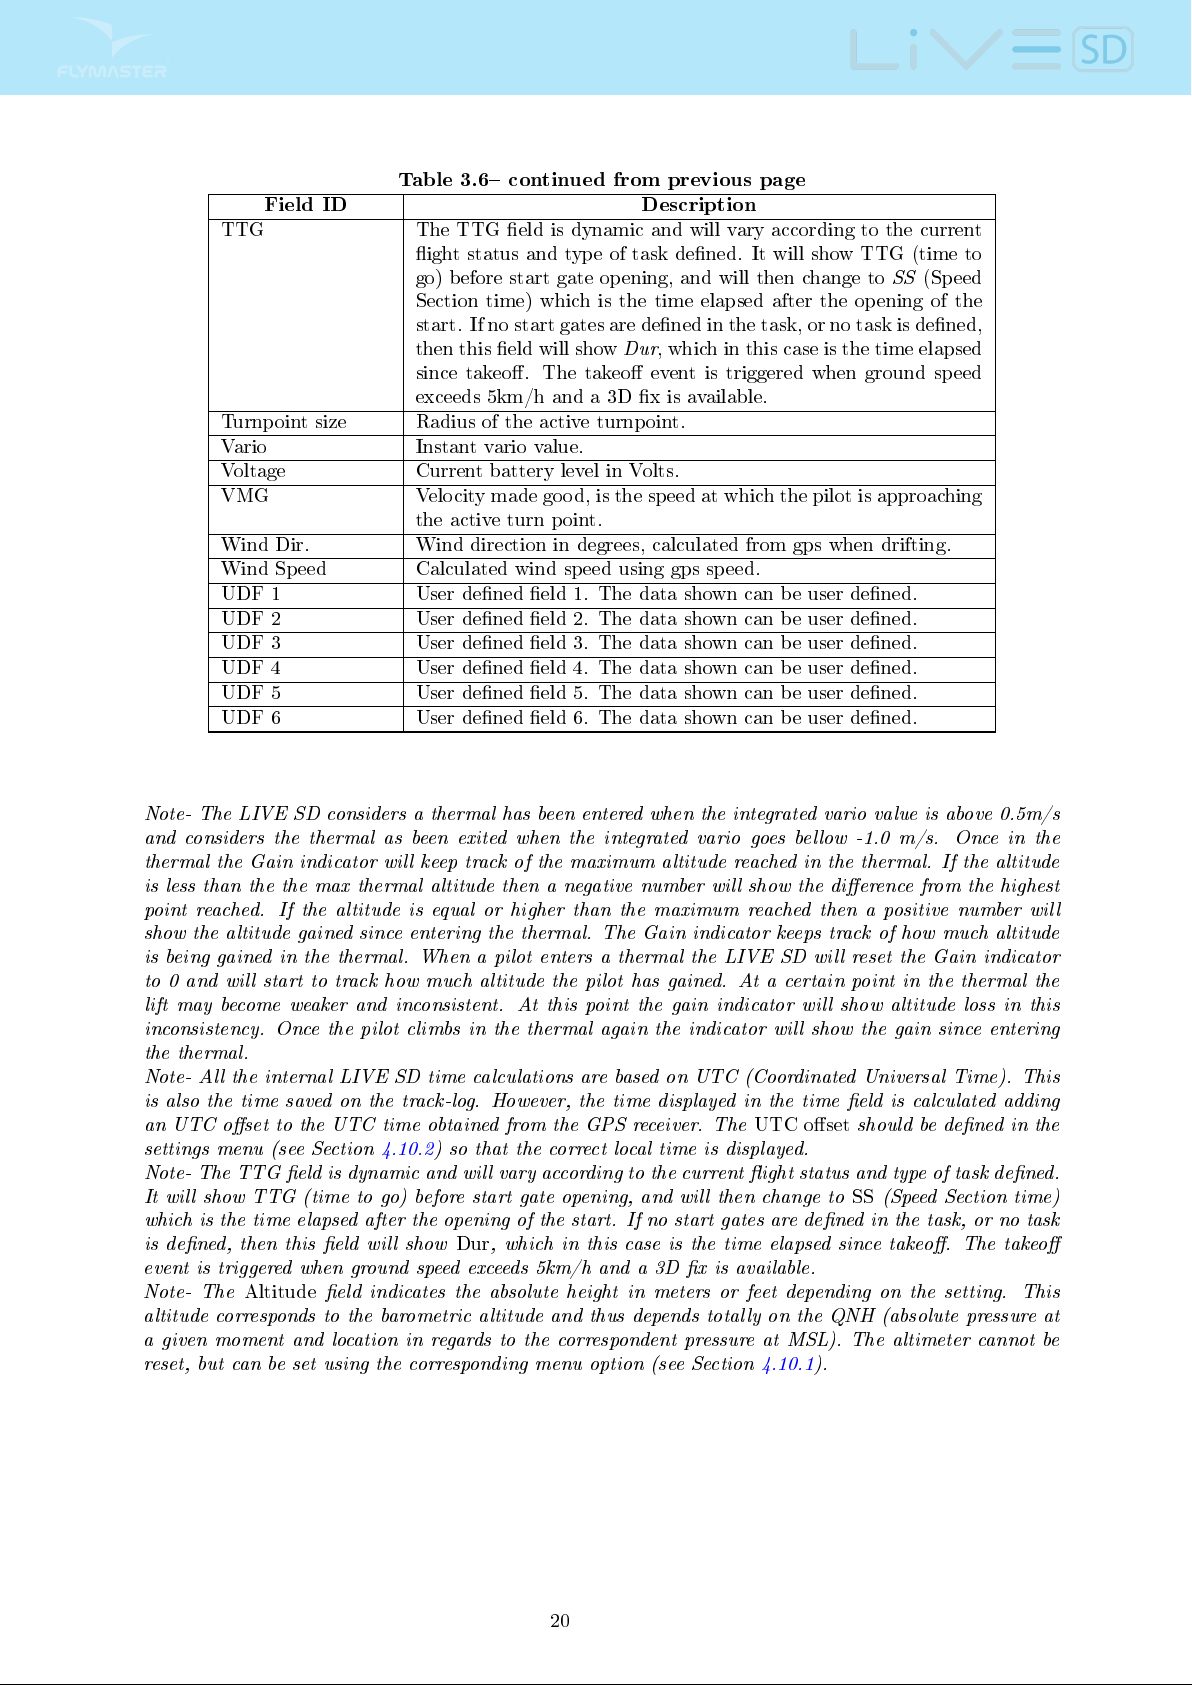
Table 3.6 continued from previous page
Field ID Description
TTG The TTG eld is dynamic and will vary according to the current
ight status and type of task dened. It will show TTG (time to
go) before start gate opening, and will then change toSS(Speed
Section time) which is the time elapsed after the opening of the
start. If no start gates are dened in the task, or no task is dened,
then this eld will show
Dur
, which in this case is the time elapsed
since takeo. The takeo event is triggered when ground speed
exceeds 5km/h and a 3D x is available.
Turnpoint size Radius of the active turnpoint.
Vario Instant vario value.
Voltage Current battery level in Volts.
VMG Velocity made good, is the speed at which the pilot is approaching
the active turn point.
Wind Dir. Wind direction in degrees, calculated from gps when drifting.
Wind Speed Calculated wind speed using gps speed.
UDF 1 User dened eld 1. The data shown can be user dened.
UDF 2 User dened eld 2. The data shown can be user dened.
UDF 3 User dened eld 3. The data shown can be user dened.
UDF 4 User dened eld 4. The data shown can be user dened.
UDF 5 User dened eld 5. The data shown can be user dened.
UDF 6 User dened eld 6. The data shown can be user dened.
Note- The LIVE SD considers a thermal has been entered when the integrated vario value is above 0.5m/s
and considers the thermal as been exited when the integrated vario goes bellow -1.0 m/s. Once in the
thermal the Gain indicator will keep track of the maximum altitude reached in the thermal. If the altitude
is less than the the max thermal altitude then a negative number will show the dierence from the highest
point reached. If the altitude is equal or higher than the maximum reached then a positive number will
show the altitude gained since entering the thermal. The Gain indicator keeps track of how much altitude
is being gained in the thermal. When a pilot enters a thermal the LIVE SD will reset the Gain indicator
to 0 and will start to track how much altitude the pilot has gained. At a certain point in the thermal the
lift may become weaker and inconsistent. At this point the gain indicator will show altitude loss in this
inconsistency. Once the pilot climbs in the thermal again the indicator will show the gain since entering
the thermal.
Note- All the internal LIVE SD time calculations are based on UTC (Coordinated Universal Time). This
is also the time saved on the track-log. However, the time displayed in the time eld is calculated adding
an UTC oset to the UTC time obtained from the GPS receiver. The
UTC oset
should be dened in the
settings menu (see Section 4.10.2) so that the correct local time is displayed.
Note- The TTG eld is dynamic and will vary according to the current ight status and type of task dened.
It will show TTG (time to go) before start gate opening, and will then change toSS(Speed Section time)
which is the time elapsed after the opening of the start. If no start gates are dened in the task, or no task
is dened, then this eld will show
Dur
, which in this case is the time elapsed since takeo. The takeo
event is triggered when ground speed exceeds 5km/h and a 3D x is available.
Note- The
Altitude
eld indicates the absolute height in meters or feet depending on the setting. This
altitude corresponds to the barometric altitude and thus depends totally on the QNH (absolute pressure at
a given moment and location in regards to the correspondent pressure at MSL). The altimeter cannot be
reset, but can be set using the corresponding menu option (see Section 4.10.1).
20
Page 22
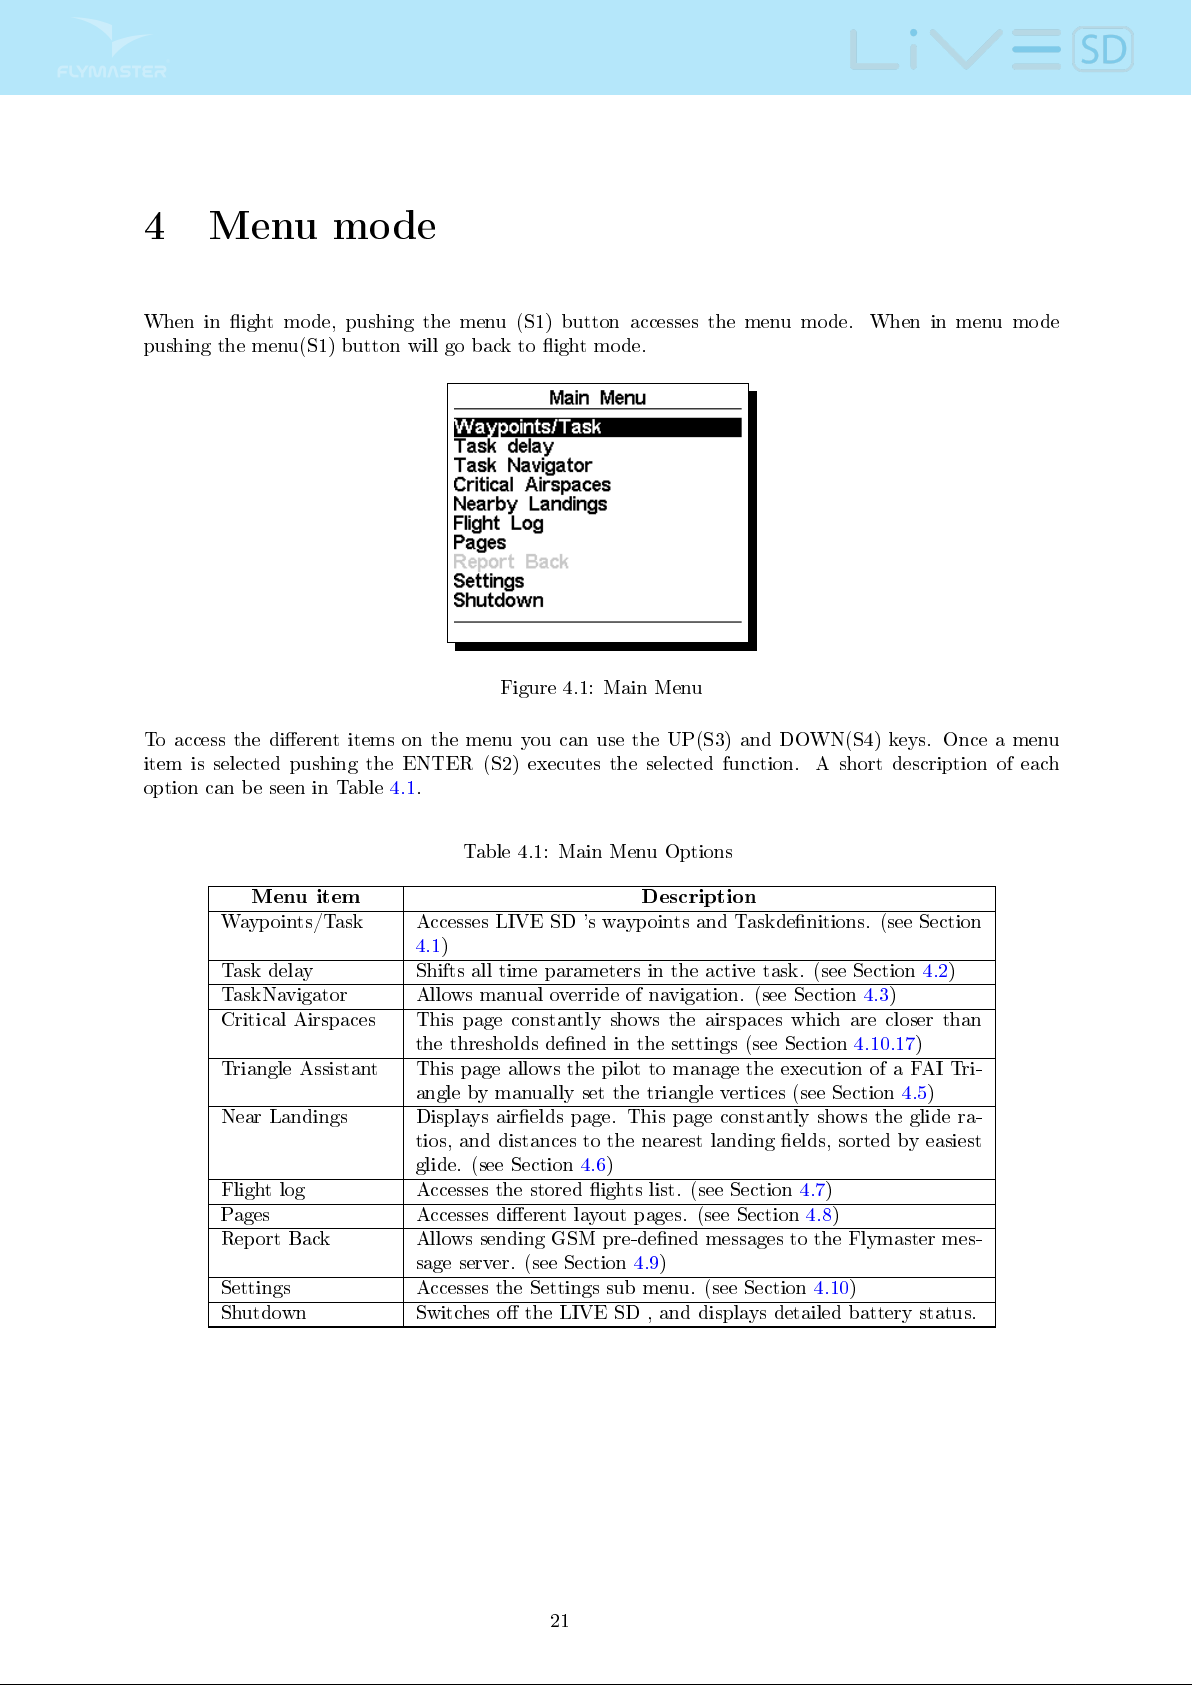
4 Menu mode
When in ight mode, pushing the menu (S1) button accesses the menu mode. When in menu mode
pushing the menu(S1) button will go back to ight mode.
Figure 4.1: Main Menu
To access the dierent items on the menu you can use the UP(S3) and DOWN(S4) keys. Once a menu
item is selected pushing the ENTER (S2) executes the selected function. A short description of each
option can be seen in Table 4.1.
Table 4.1: Main Menu Options
Menu item Description
Waypoints/Task Accesses LIVE SD 's waypoints and Taskdenitions. (see Section
4.1)
Task delay Shifts all time parameters in the active task. (see Section 4.2)
TaskNavigator Allows manual override of navigation. (see Section 4.3)
Critical Airspaces This page constantly shows the airspaces which are closer than
the thresholds dened in the settings (see Section 4.10.17)
Triangle Assistant This page allows the pilot to manage the execution of a FAI Tri-
angle by manually set the triangle vertices (see Section 4.5)
Near Landings Displays airelds page. This page constantly shows the glide ra-
tios, and distances to the nearest landing elds, sorted by easiest
glide. (see Section 4.6)
Flight log Accesses the stored ights list. (see Section 4.7)
Pages Accesses dierent layout pages. (see Section 4.8)
Report Back Allows sending GSM pre-dened messages to the Flymaster mes-
sage server. (see Section 4.9)
Settings Accesses the Settings sub menu. (see Section 4.10)
Shutdown Switches o the LIVE SD , and displays detailed battery status.
21
Page 23
4.1 Waypoints and Task
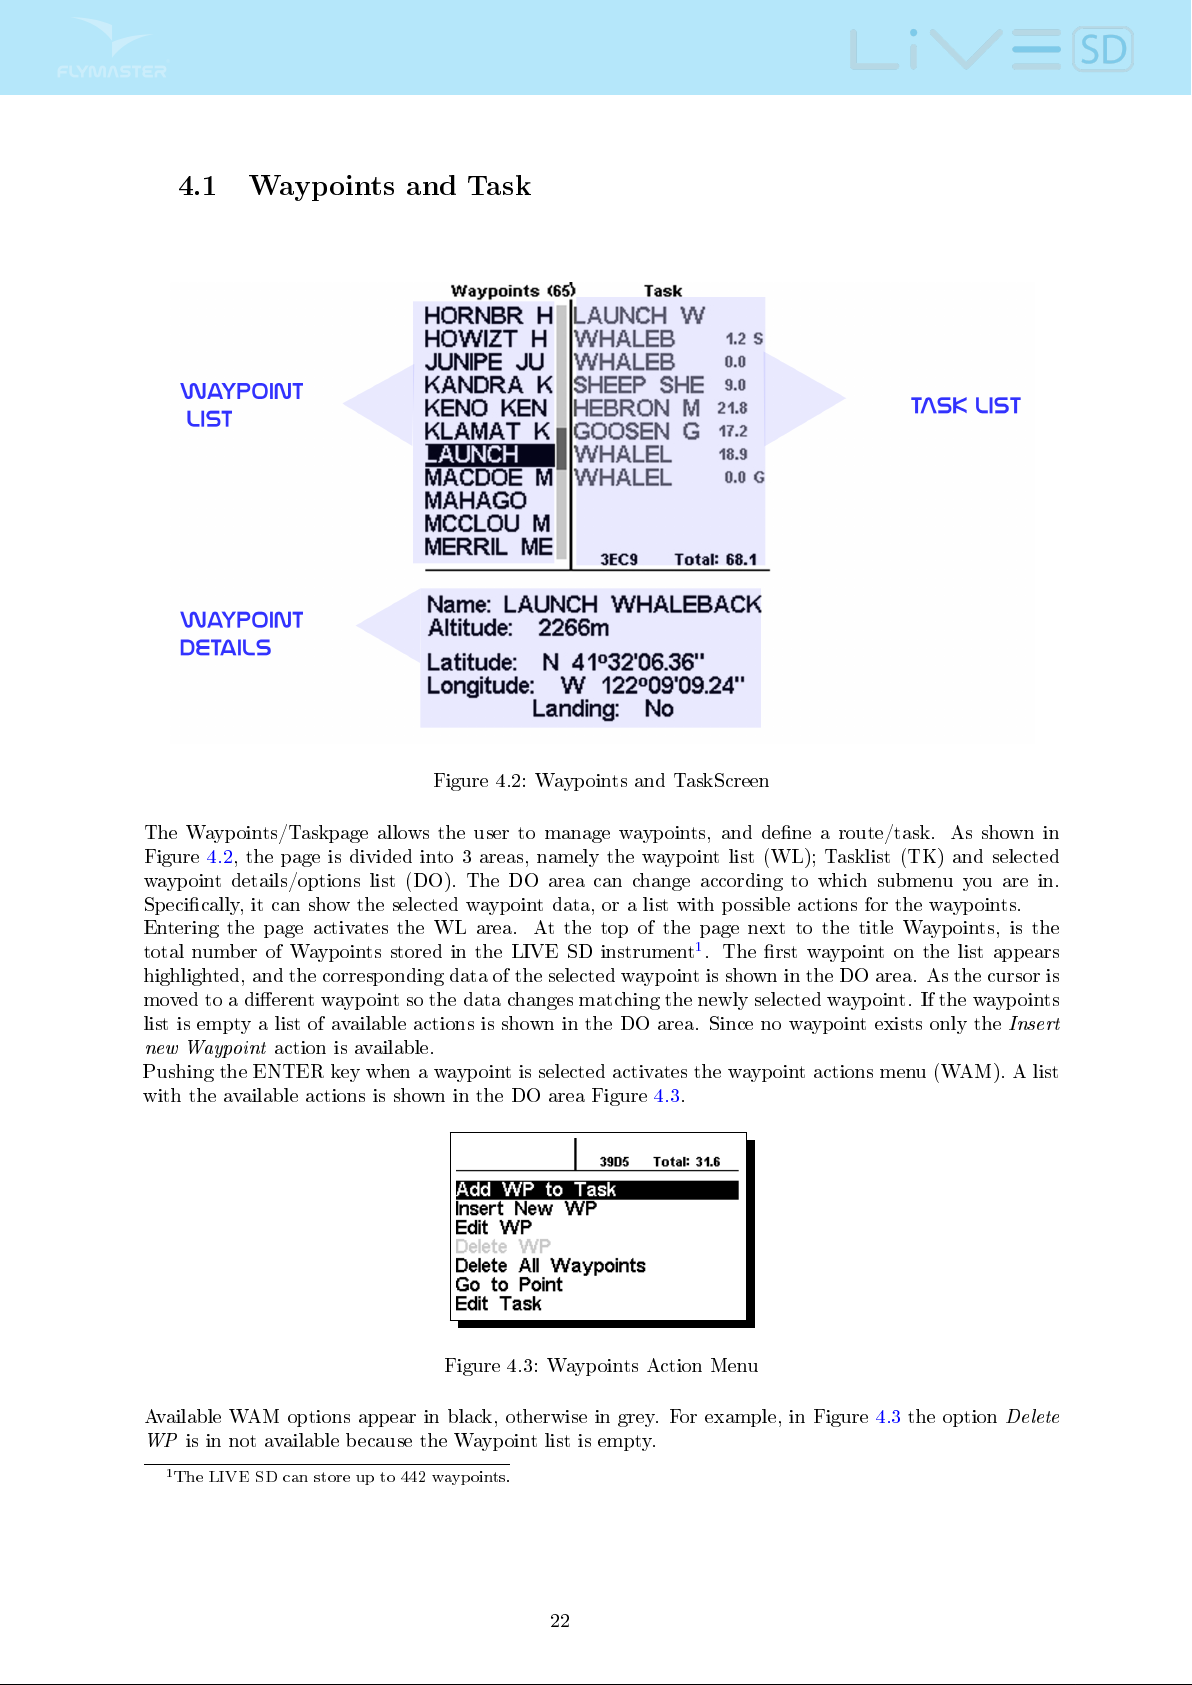
Figure 4.2: Waypoints and TaskScreen
The Waypoints/Taskpage allows the user to manage waypoints, and dene a route/task. As shown in
Figure 4.2, the page is divided into 3 areas, namely the waypoint list (WL); Tasklist (TK) and selected
waypoint details/options list (DO). The DO area can change according to which submenu you are in.
Specically, it can show the selected waypoint data, or a list with possible actions for the waypoints.
Entering the page activates the WL area. At the top of the page next to the title Waypoints, is the
total number of Waypoints stored in the LIVE SD instrument1. The rst waypoint on the list appears
highlighted, and the corresponding data of the selected waypoint is shown in the DO area. As the cursor is
moved to a dierent waypoint so the data changes matching the newly selected waypoint. If the waypoints
list is empty a list of available actions is shown in the DO area. Since no waypoint exists only the
new Waypoint
action is available.
Insert
Pushing the ENTER key when a waypoint is selected activates the waypoint actions menu (WAM). A list
with the available actions is shown in the DO area Figure 4.3.
Figure 4.3: Waypoints Action Menu
Available WAM options appear in black, otherwise in grey. For example, in Figure 4.3 the option
WP
is in not available because the Waypoint list is empty.
1
The LIVE SD can store up to 442 waypoints.
22
Delete
Page 24
4.1.1 Waypoints Actions Menu
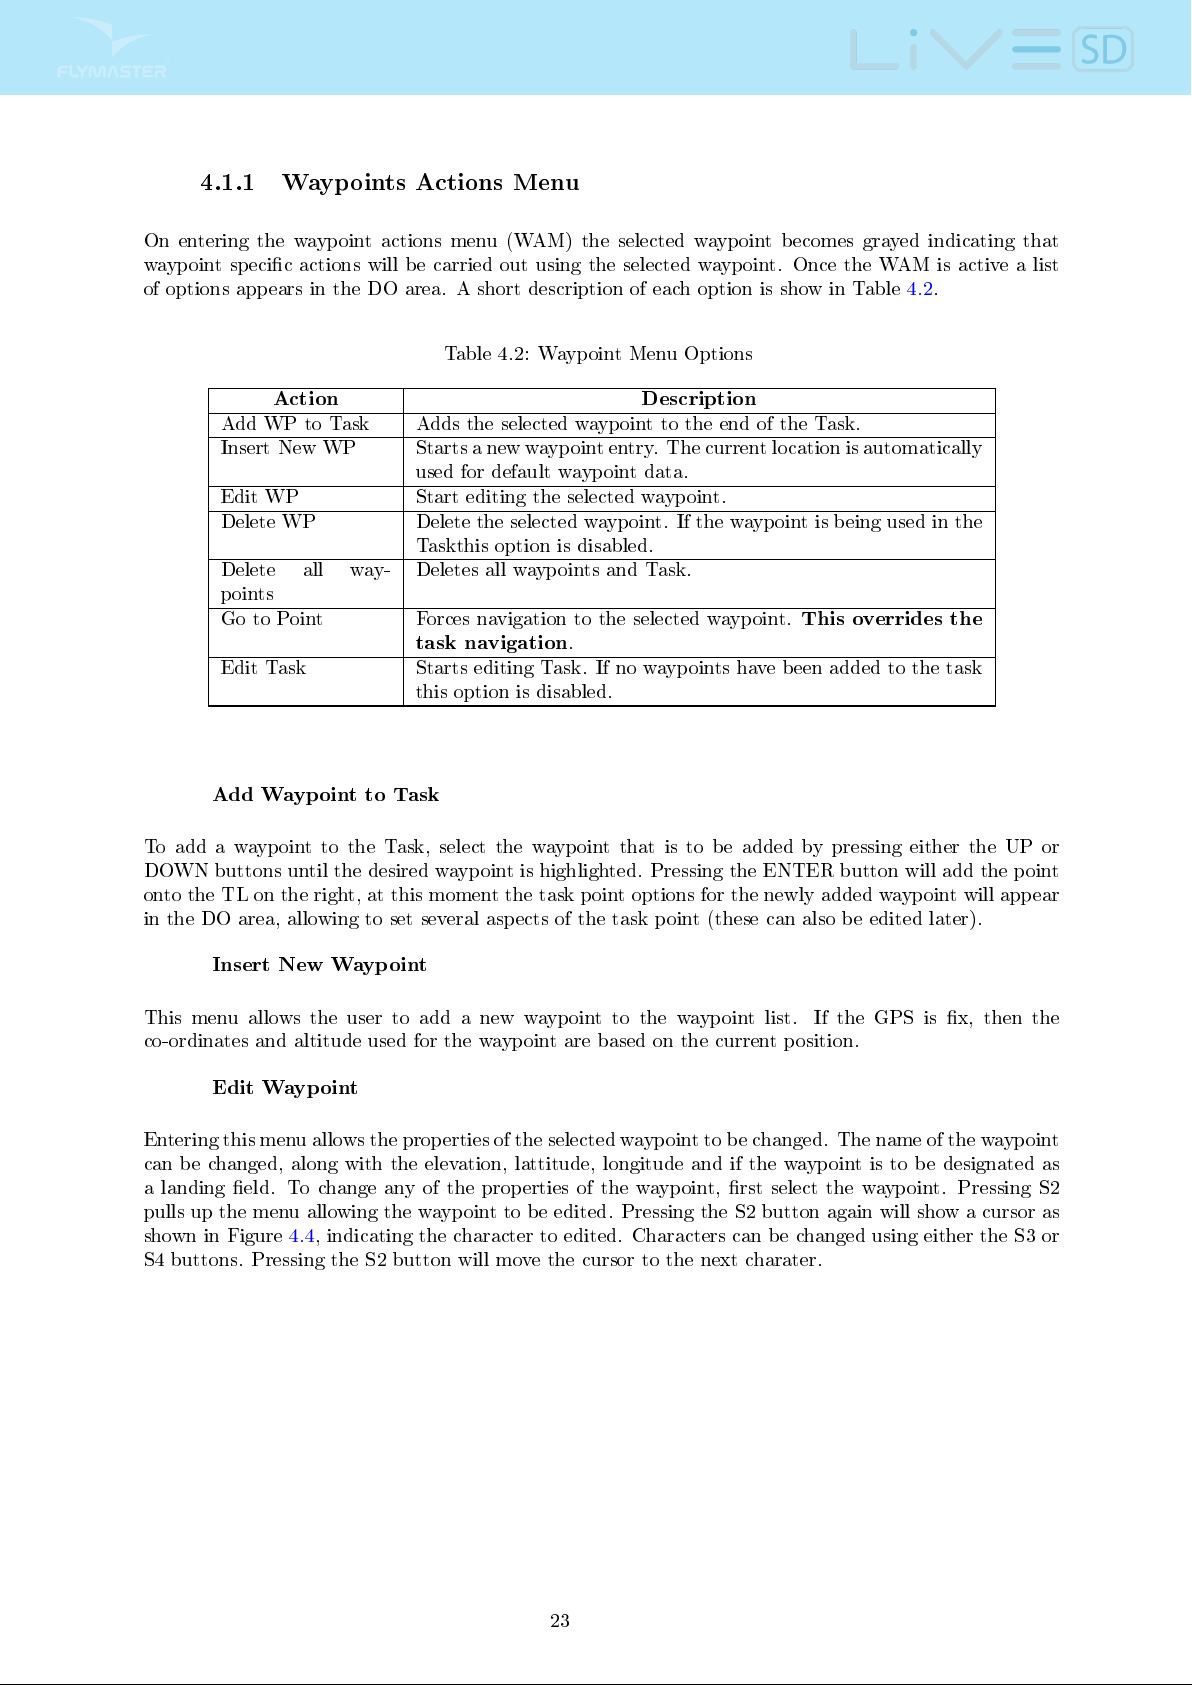
On entering the waypoint actions menu (WAM) the selected waypoint becomes grayed indicating that
waypoint specic actions will be carried out using the selected waypoint. Once the WAM is active a list
of options appears in the DO area. A short description of each option is show in Table 4.2.
Table 4.2: Waypoint Menu Options
Action Description
Add WP to Task Adds the selected waypoint to the end of the Task.
Insert New WP Starts a new waypoint entry. The current location is automatically
used for default waypoint data.
Edit WP Start editing the selected waypoint.
Delete WP Delete the selected waypoint. If the waypoint is being used in the
Taskthis option is disabled.
Delete all way-
points
Go to Point Forces navigation to the selected waypoint.
Edit Task Starts editing Task. If no waypoints have been added to the task
Deletes all waypoints and Task.
task navigation
this option is disabled.
.
This overrides the
Add Waypoint to Task
To add a waypoint to the Task, select the waypoint that is to be added by pressing either the UP or
DOWN buttons until the desired waypoint is highlighted. Pressing the ENTER button will add the point
onto the TL on the right, at this moment the task point options for the newly added waypoint will appear
in the DO area, allowing to set several aspects of the task point (these can also be edited later).
Insert New Waypoint
This menu allows the user to add a new waypoint to the waypoint list. If the GPS is x, then the
co-ordinates and altitude used for the waypoint are based on the current position.
Edit Waypoint
Entering this menu allows the properties of the selected waypoint to be changed. The name of the waypoint
can be changed, along with the elevation, lattitude, longitude and if the waypoint is to be designated as
a landing eld. To change any of the properties of the waypoint, rst select the waypoint. Pressing S2
pulls up the menu allowing the waypoint to be edited. Pressing the S2 button again will show a cursor as
shown in Figure 4.4, indicating the character to edited. Characters can be changed using either the S3 or
S4 buttons. Pressing the S2 button will move the cursor to the next charater.
23
Page 25
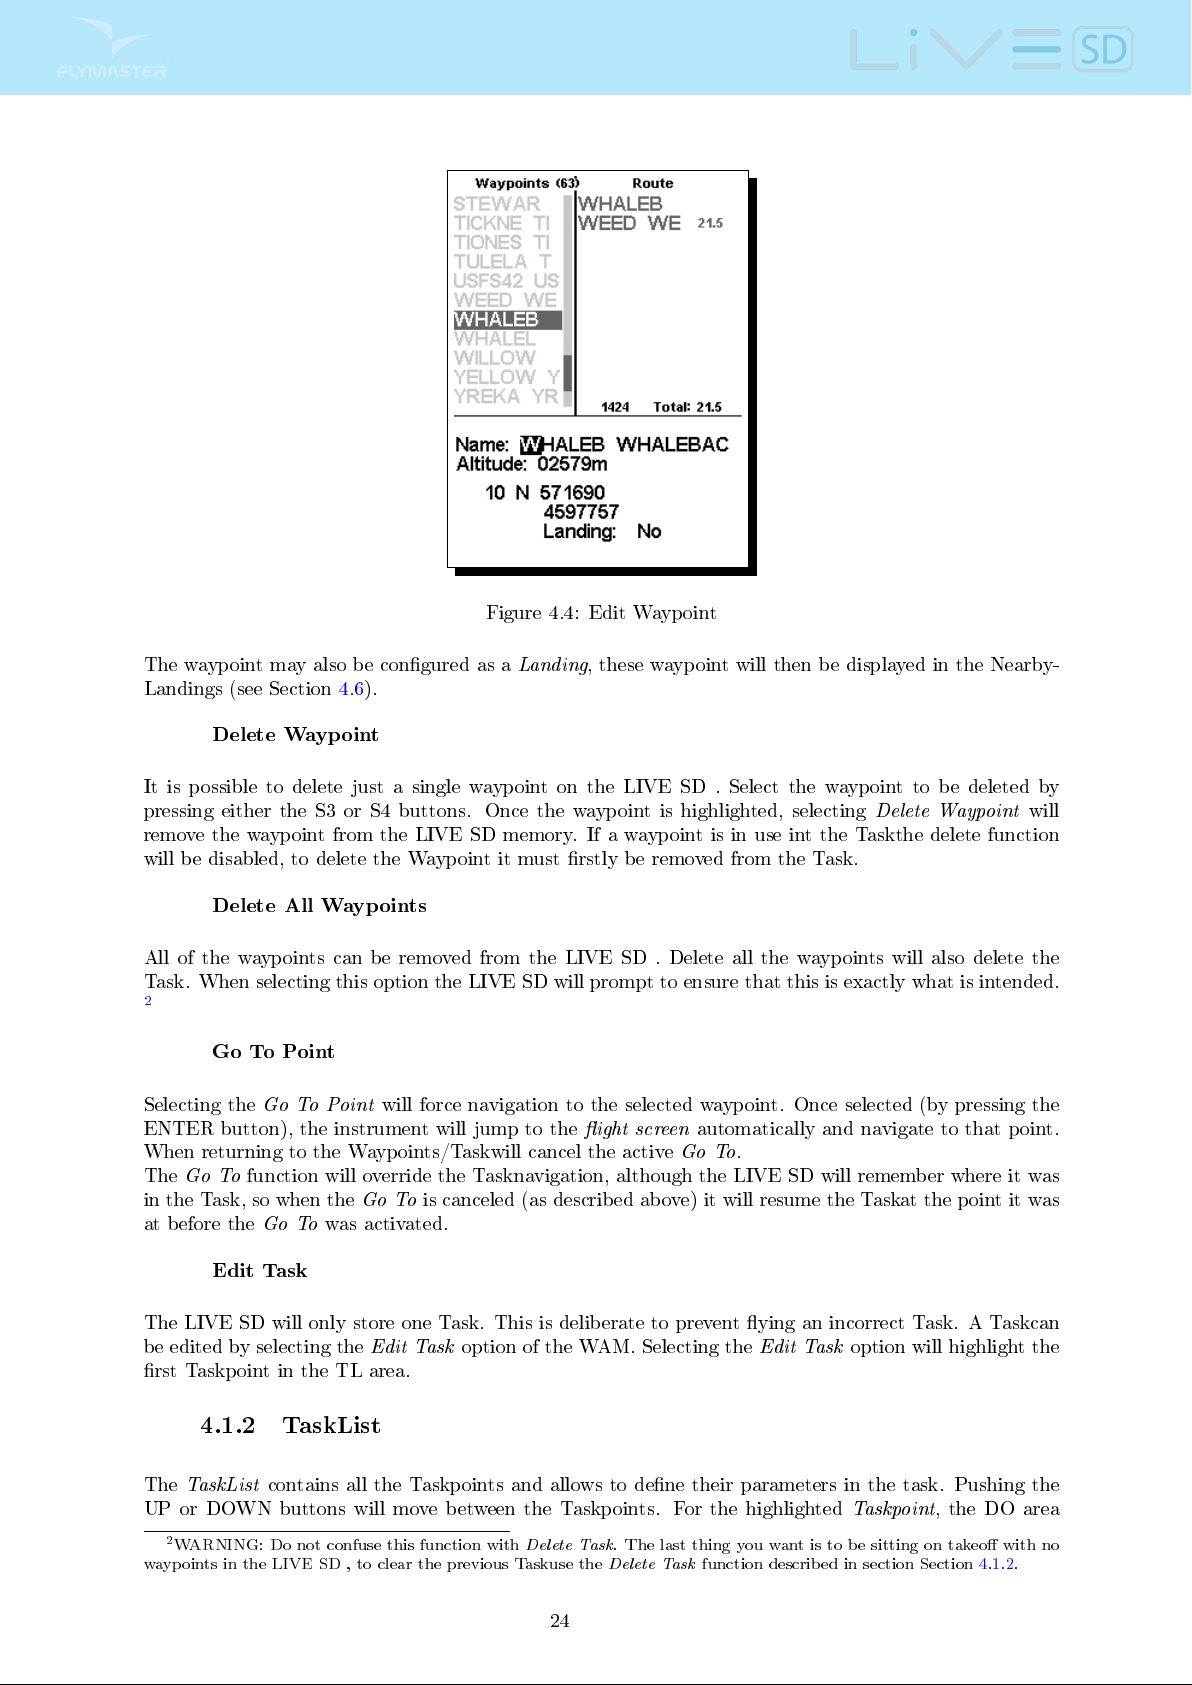
Figure 4.4: Edit Waypoint
The waypoint may also be congured as a
Landing
, these waypoint will then be displayed in the Nearby-
Landings (see Section 4.6).
Delete Waypoint
It is possible to delete just a single waypoint on the LIVE SD . Select the waypoint to be deleted by
pressing either the S3 or S4 buttons. Once the waypoint is highlighted, selecting
Delete Waypoint
will
remove the waypoint from the LIVE SD memory. If a waypoint is in use int the Taskthe delete function
will be disabled, to delete the Waypoint it must rstly be removed from the Task.
Delete All Waypoints
All of the waypoints can be removed from the LIVE SD . Delete all the waypoints will also delete the
Task. When selecting this option the LIVE SD will prompt to ensure that this is exactly what is intended.
2
Go To Point
Selecting the
ENTER button), the instrument will jump to the
When returning to the Waypoints/Taskwill cancel the active
The
Go To
in the Task, so when the
at before the
Go To Point
will force navigation to the selected waypoint. Once selected (by pressing the
ight screen
automatically and navigate to that point.
Go To
.
function will override the Tasknavigation, although the LIVE SD will remember where it was
Go To
Go To
was activated.
is canceled (as described above) it will resume the Taskat the point it was
Edit Task
The LIVE SD will only store one Task. This is deliberate to prevent ying an incorrect Task. A Taskcan
be edited by selecting the
Edit Task
option of the WAM. Selecting the
Edit Task
option will highlight the
rst Taskpoint in the TL area.
4.1.2 TaskList
The
TaskList
UP or DOWN buttons will move between the Taskpoints. For the highlighted
2
WARNING: Do not confuse this function with
waypoints in the LIVE SD , to clear the previous Taskuse the
contains all the Taskpoints and allows to dene their parameters in the task. Pushing the
Delete Task
Taskpoint
. The last thing you want is to be sitting on takeo with no
Delete Task
function described in section Section 4.1.2.
, the DO area
24
Page 26
will display the
Taskpoint
parameters.3When a Taskhas only one point it is considered as a
route. The LIVE SD will automatically start navigating to that point.
Note: When the Taskcontains more than one point then the rst turn point will automati-
cally be set as
Take-O
. The
Take-o
is ignored for navigation proposes and is only used for
calculating the total task distance.
Go To
type
Pushing ENTER while on a selected Taskpoint will open a
of the screen), which will allow you to
Edit,MoveorRemove
TaskPoint Menu
in the DO area (at the bottom
a point from the Task. Each
Taskpoint
dened
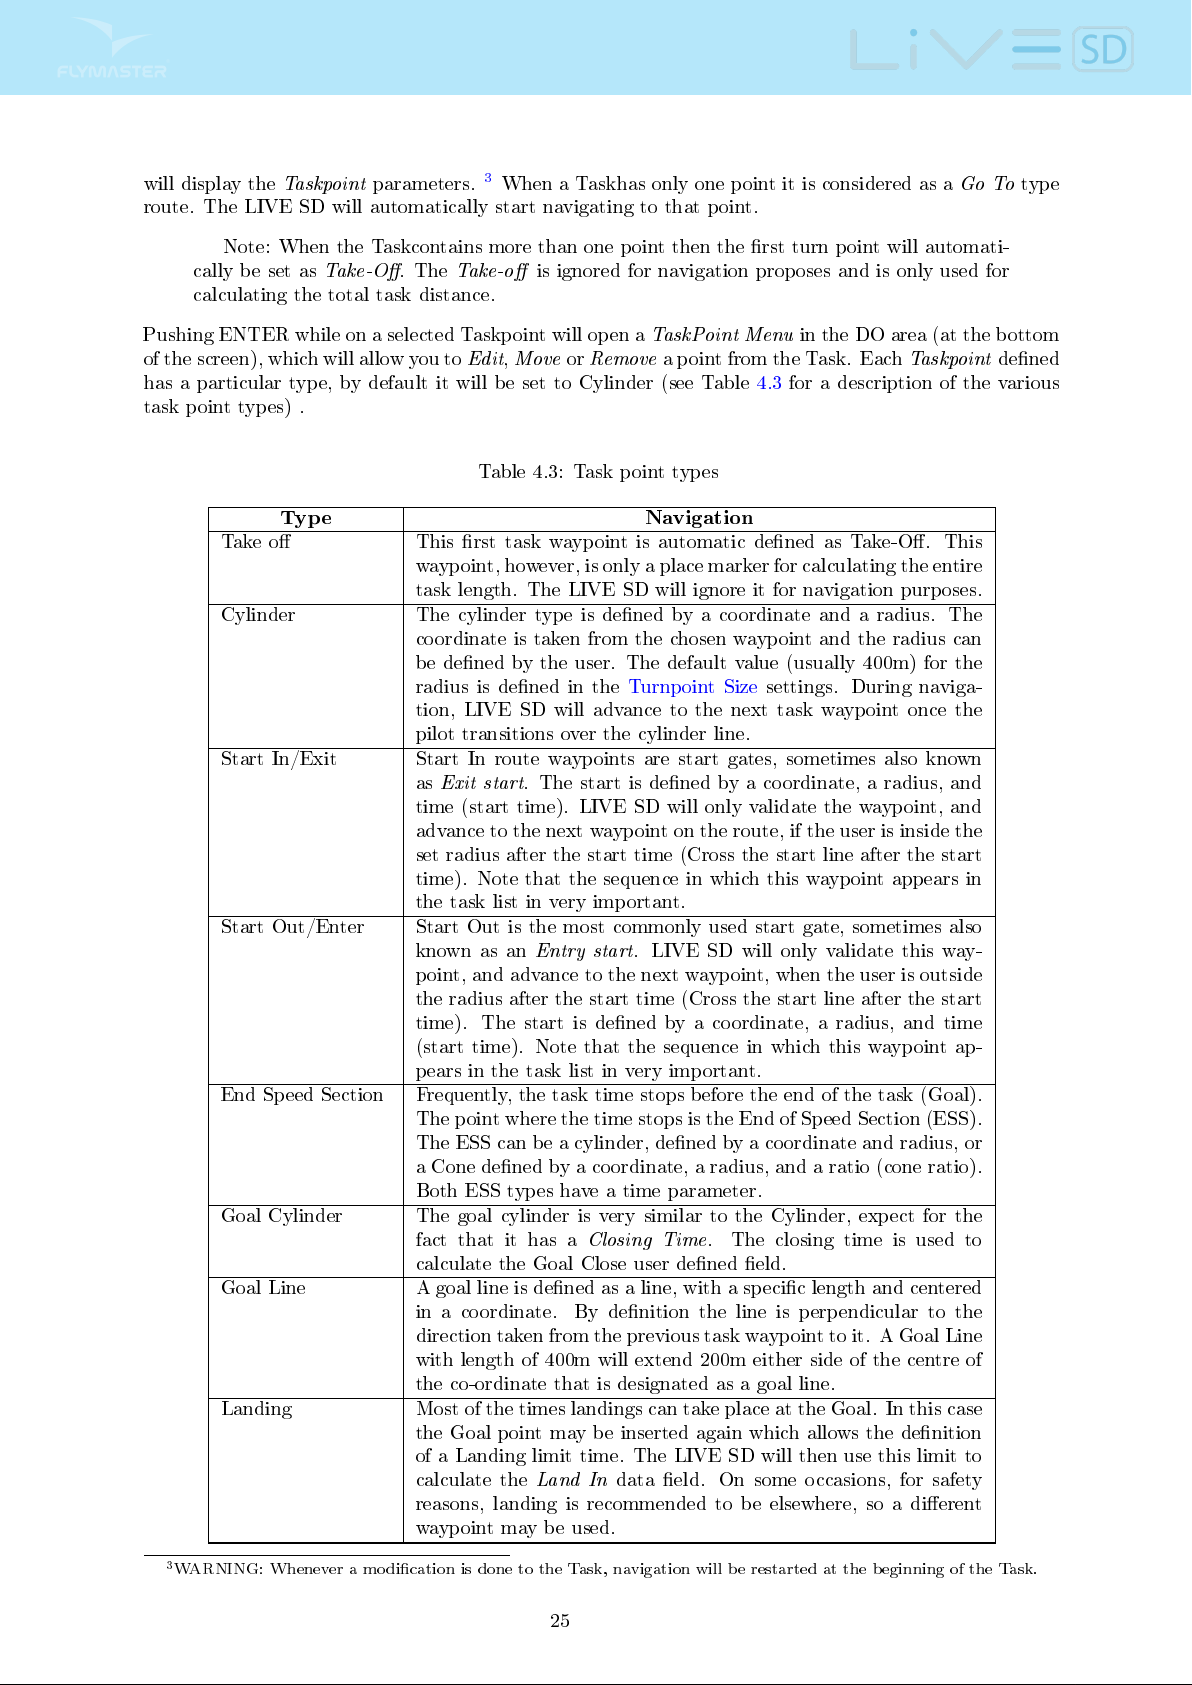
has a particular type, by default it will be set to Cylinder (see Table 4.3 for a description of the various
task point types) .
Table 4.3: Task point types
Type Navigation
Take o This rst task waypoint is automatic dened as Take-O. This
waypoint, however, is only a place marker for calculating the entire
task length. The LIVE SD will ignore it for navigation purposes.
Cylinder The cylinder type is dened by a coordinate and a radius. The
coordinate is taken from the chosen waypoint and the radius can
be dened by the user. The default value (usually 400m) for the
radius is dened in the Turnpoint Size settings. During naviga-
tion, LIVE SD will advance to the next task waypoint once the
pilot transitions over the cylinder line.
Start In/Exit Start In route waypoints are start gates, sometimes also known
as
Exit start
. The start is dened by a coordinate, a radius, and
time (start time). LIVE SD will only validate the waypoint, and
advance to the next waypoint on the route, if the user is inside the
set radius after the start time (Cross the start line after the start
time). Note that the sequence in which this waypoint appears in
the task list in very important.
Start Out/Enter Start Out is the most commonly used start gate, sometimes also
known as an
Entry start
. LIVE SD will only validate this way-
point, and advance to the next waypoint, when the user is outside
the radius after the start time (Cross the start line after the start
time). The start is dened by a coordinate, a radius, and time
(start time). Note that the sequence in which this waypoint ap-
pears in the task list in very important.
End Speed Section Frequently, the task time stops before the end of the task (Goal).
The point where the time stops is the End of Speed Section (ESS).
The ESS can be a cylinder, dened by a coordinate and radius, or
a Cone dened by a coordinate, a radius, and a ratio (cone ratio).
Both ESS types have a time parameter.
Goal Cylinder The goal cylinder is very similar to the Cylinder, expect for the
fact that it has a
Closing Time
. The closing time is used to
calculate the Goal Close user dened eld.
Goal Line A goal line is dened as a line, with a specic length and centered
in a coordinate. By denition the line is perpendicular to the
direction taken from the previous task waypoint to it. A Goal Line
with length of 400m will extend 200m either side of the centre of
the co-ordinate that is designated as a goal line.
Landing Most of the times landings can take place at the Goal. In this case
the Goal point may be inserted again which allows the denition
of a Landing limit time. The LIVE SD will then use this limit to
calculate the
Land In
data eld. On some occasions, for safety
reasons, landing is recommended to be elsewhere, so a dierent
waypoint may be used.
3
WARNING: Whenever a modication is done to the Task, navigation will be restarted at the beginning of the Task.
25
Page 27
When the LIVE SD validates a turnpoint it emits a audible notice informing the user that navigation
has advanced to the next waypoint, this audible notice can be disabled in the Alerts setting (see Section
4.10.4).
Edit route point
When
task points
for the rst one, as mentioned above, which is set as
are added to the task by default their type is Cylinder and have a 400m radius, (except
Take-o
).4To modify a particular
task point
, select
the task point using the UP or DOWN buttons, then push ENTER to open the Task Point Menu. Finally
select the
the
Edit Route Point
task point type
and push ENTER. The task point parameters can now be edited. Changing
will cause the
Time
eld to be displayed when applicable.
Very important: The sequence in which the waypoints are listed is critical since the LIVE
SD will navigate them in that order, so in the case of a start gate which is also a turn point
(as is commonly used in competition tasks) the start must be placed before the turn point.
The
Time
is only available on turn point types that are time related, so the
when the turn point type requires a time (e.g. Start gates and goals). Table 4.4 describes how
Time
eld will only be visible
Time
data
is used for each eld type.
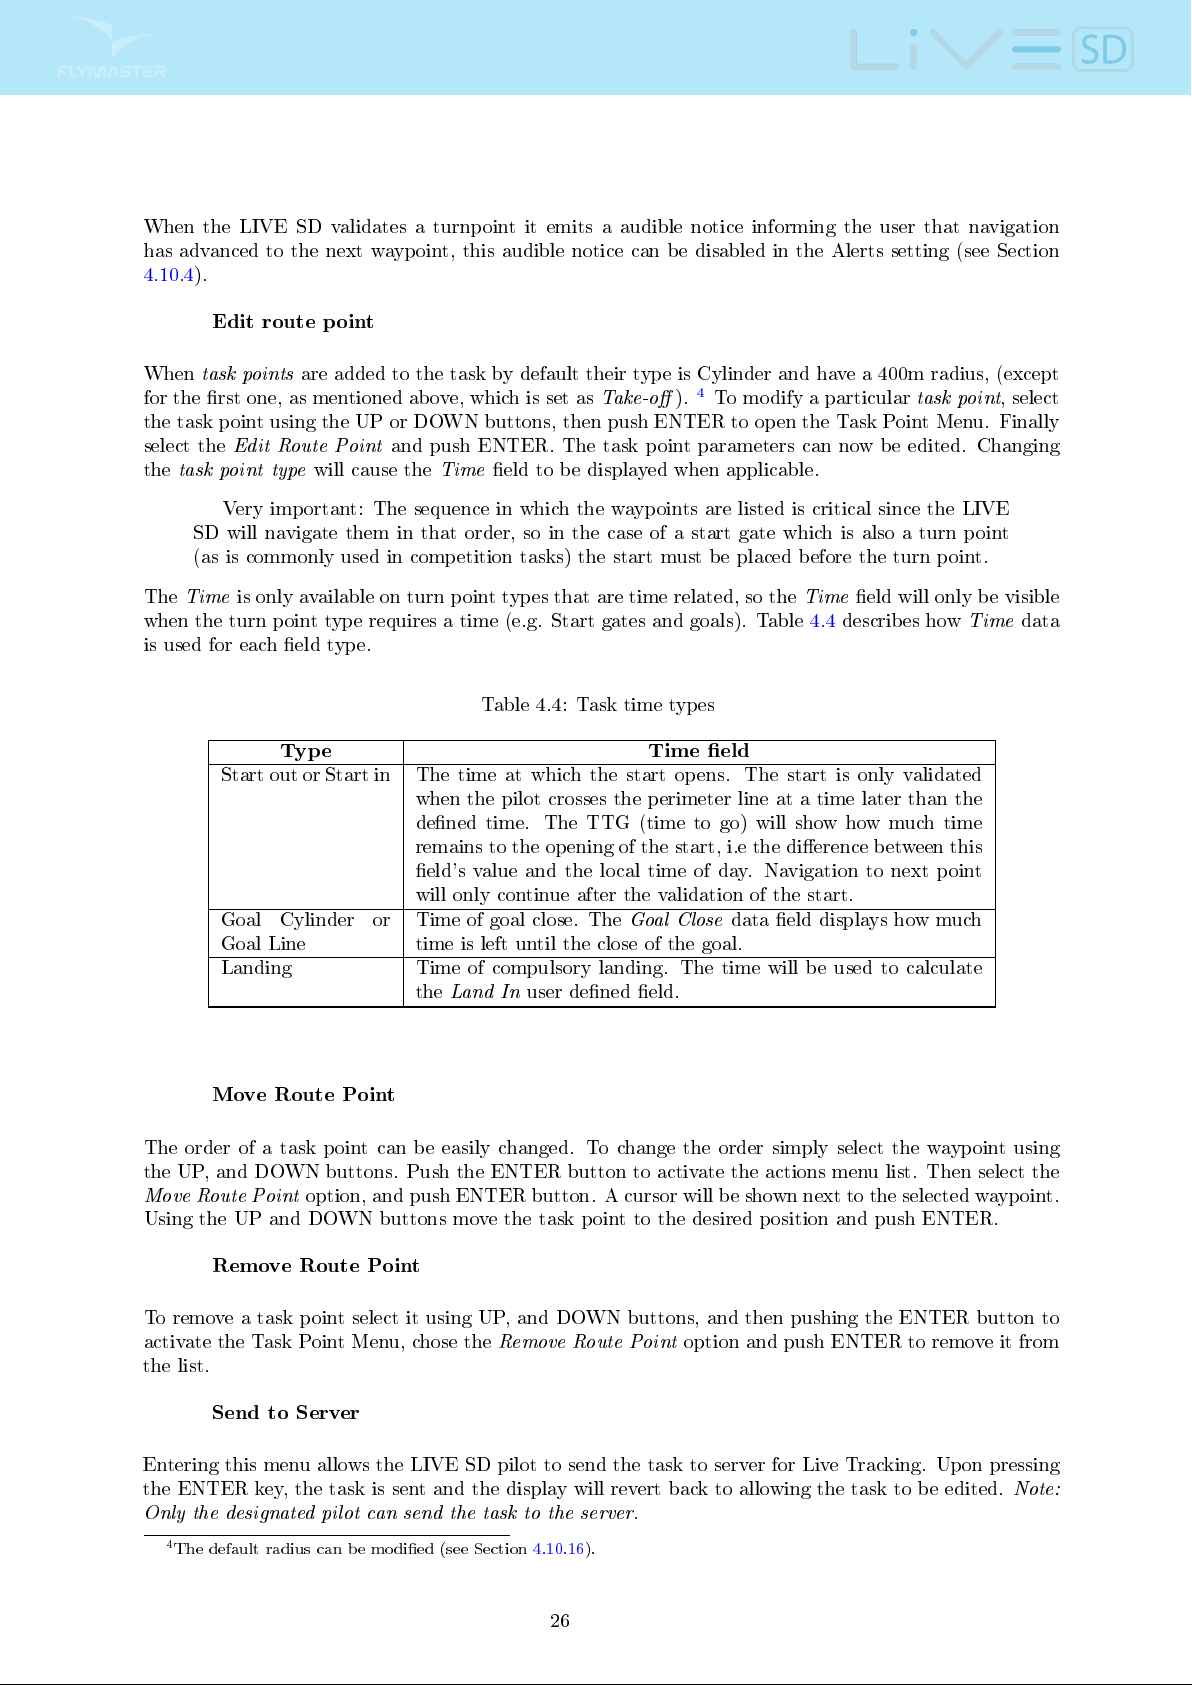
Table 4.4: Task time types
Type Time eld
Start out or Start in The time at which the start opens. The start is only validated
when the pilot crosses the perimeter line at a time later than the
dened time. The TTG (time to go) will show how much time
remains to the opening of the start, i.e the dierence between this
eld's value and the local time of day. Navigation to next point
will only continue after the validation of the start.
Goal Cylinder or
Goal Line
Time of goal close. The
Goal Close
time is left until the close of the goal.
data eld displays how much
Landing Time of compulsory landing. The time will be used to calculate
the
Land In
user dened eld.
Move Route Point
The order of a task point can be easily changed. To change the order simply select the waypoint using
the UP, and DOWN buttons. Push the ENTER button to activate the actions menu list. Then select the
Move Route Point
option, and push ENTER button. A cursor will be shown next to the selected waypoint.
Using the UP and DOWN buttons move the task point to the desired position and push ENTER.
Remove Route Point
To remove a task point select it using UP, and DOWN buttons, and then pushing the ENTER button to
activate the Task Point Menu, chose the
Remove Route Point
option and push ENTER to remove it from
the list.
Send to Server
Entering this menu allows the LIVE SD pilot to send the task to server for Live Tracking. Upon pressing
the ENTER key, the task is sent and the display will revert back to allowing the task to be edited.
Note:
Only the designated pilot can send the task to the server.
4
The default radius can be modied (see Section 4.10.16).
26
Page 28
Get Task from Server
Entering this menu allows the LIVE SD pilot to get a task from the Flymaster server. The task is sent if
it exists, and the pilot is registered in the competition. Upon pressing the ENTER key, the LIVE SD will
return to the Fligth Screen with the navigation active.
Delete Task
Delete Taskwill delete the entire route. On any waypoint push the ENTER button to activate the actions
menu list. Select the
route will be deleted and the WL area activated.
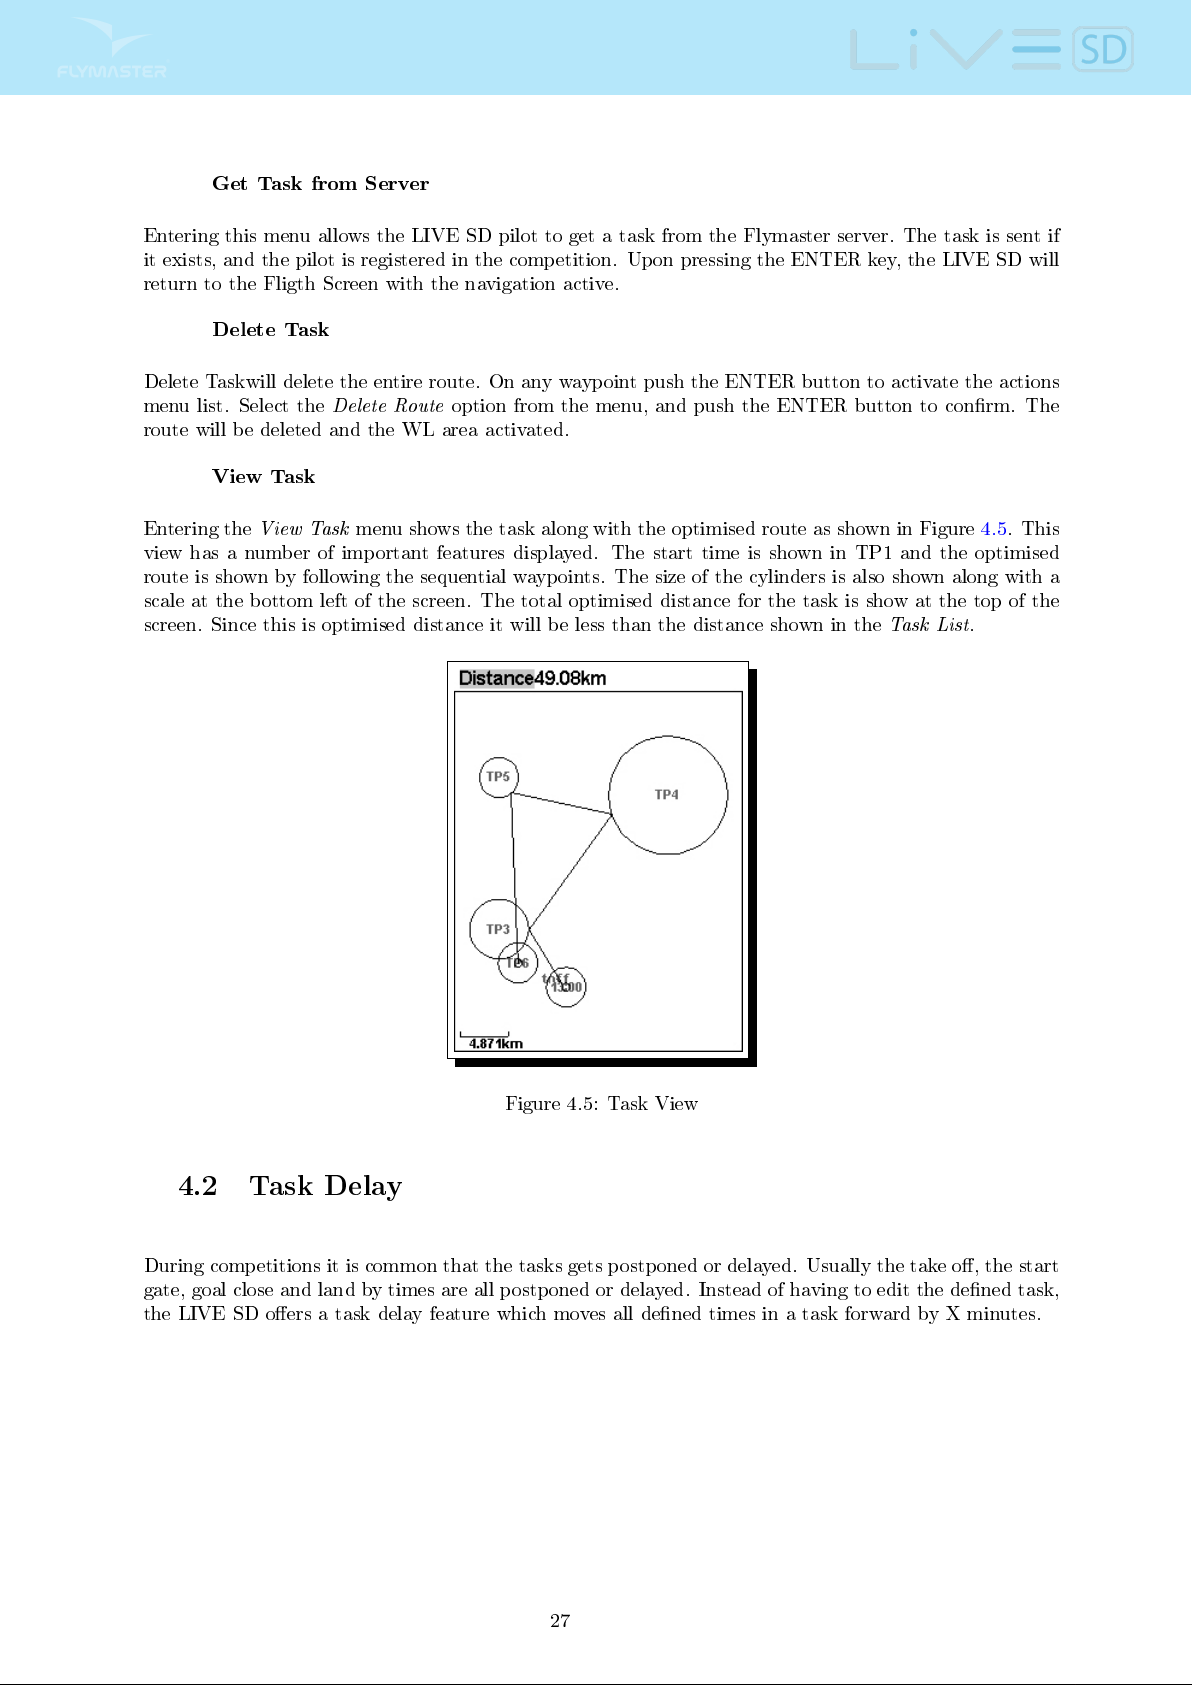
View Task
Delete Route
option from the menu, and push the ENTER button to conrm. The
Entering the
view has a number of important features displayed. The start time is shown in TP1 and the optimised
route is shown by following the sequential waypoints. The size of the cylinders is also shown along with a
scale at the bottom left of the screen. The total optimised distance for the task is show at the top of the
screen. Since this is optimised distance it will be less than the distance shown in the
View Task
menu shows the task along with the optimised route as shown in Figure 4.5. This
Task List
Figure 4.5: Task View
.
4.2 Task Delay
During competitions it is common that the tasks gets postponed or delayed. Usually the take o, the start
gate, goal close and land by times are all postponed or delayed. Instead of having to edit the dened task,
the LIVE SD oers a task delay feature which moves all dened times in a task forward by X minutes.
27
Page 29
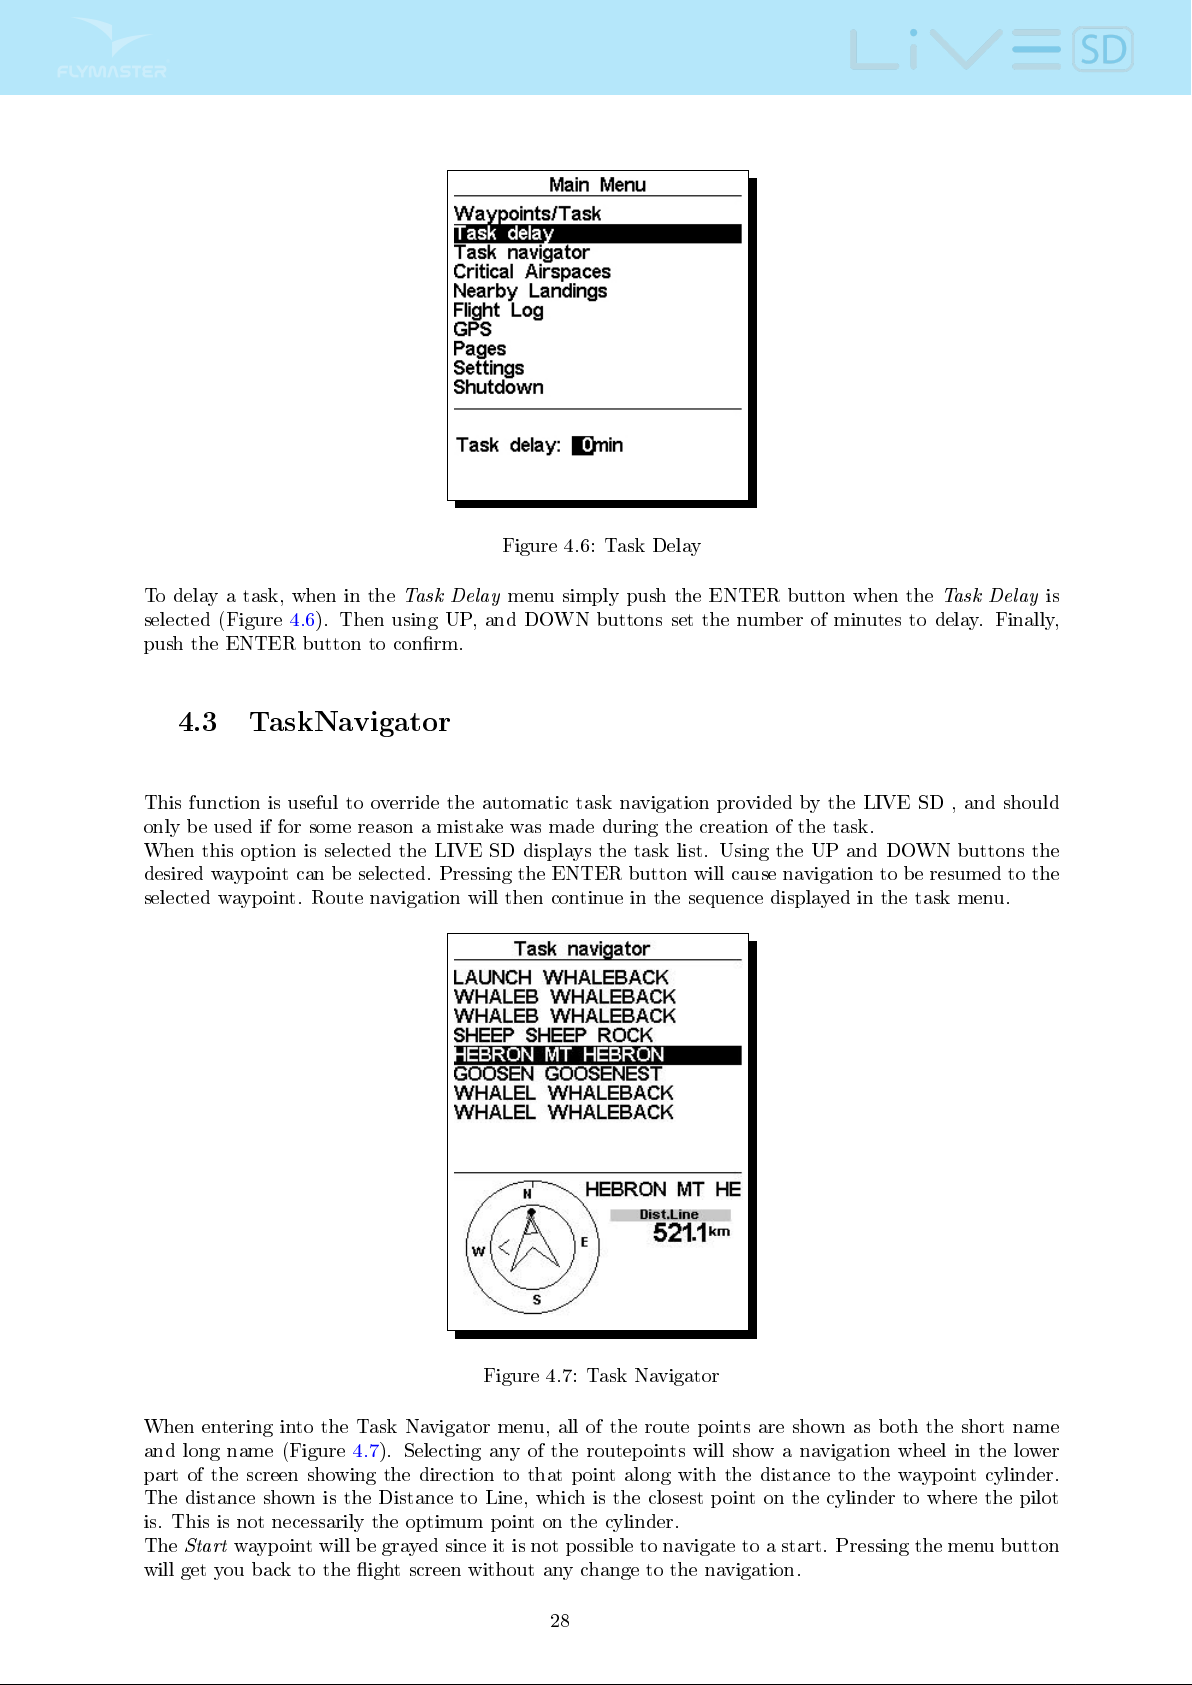
Figure 4.6: Task Delay
To delay a task, when in the
selected (Figure 4.6). Then using UP, and DOWN buttons set the number of minutes to delay. Finally,
push the ENTER button to conrm.
Task Delay
menu simply push the ENTER button when the
Task Delay
4.3 TaskNavigator
This function is useful to override the automatic task navigation provided by the LIVE SD , and should
only be used if for some reason a mistake was made during the creation of the task.
When this option is selected the LIVE SD displays the task list. Using the UP and DOWN buttons the
desired waypoint can be selected. Pressing the ENTER button will cause navigation to be resumed to the
selected waypoint. Route navigation will then continue in the sequence displayed in the task menu.
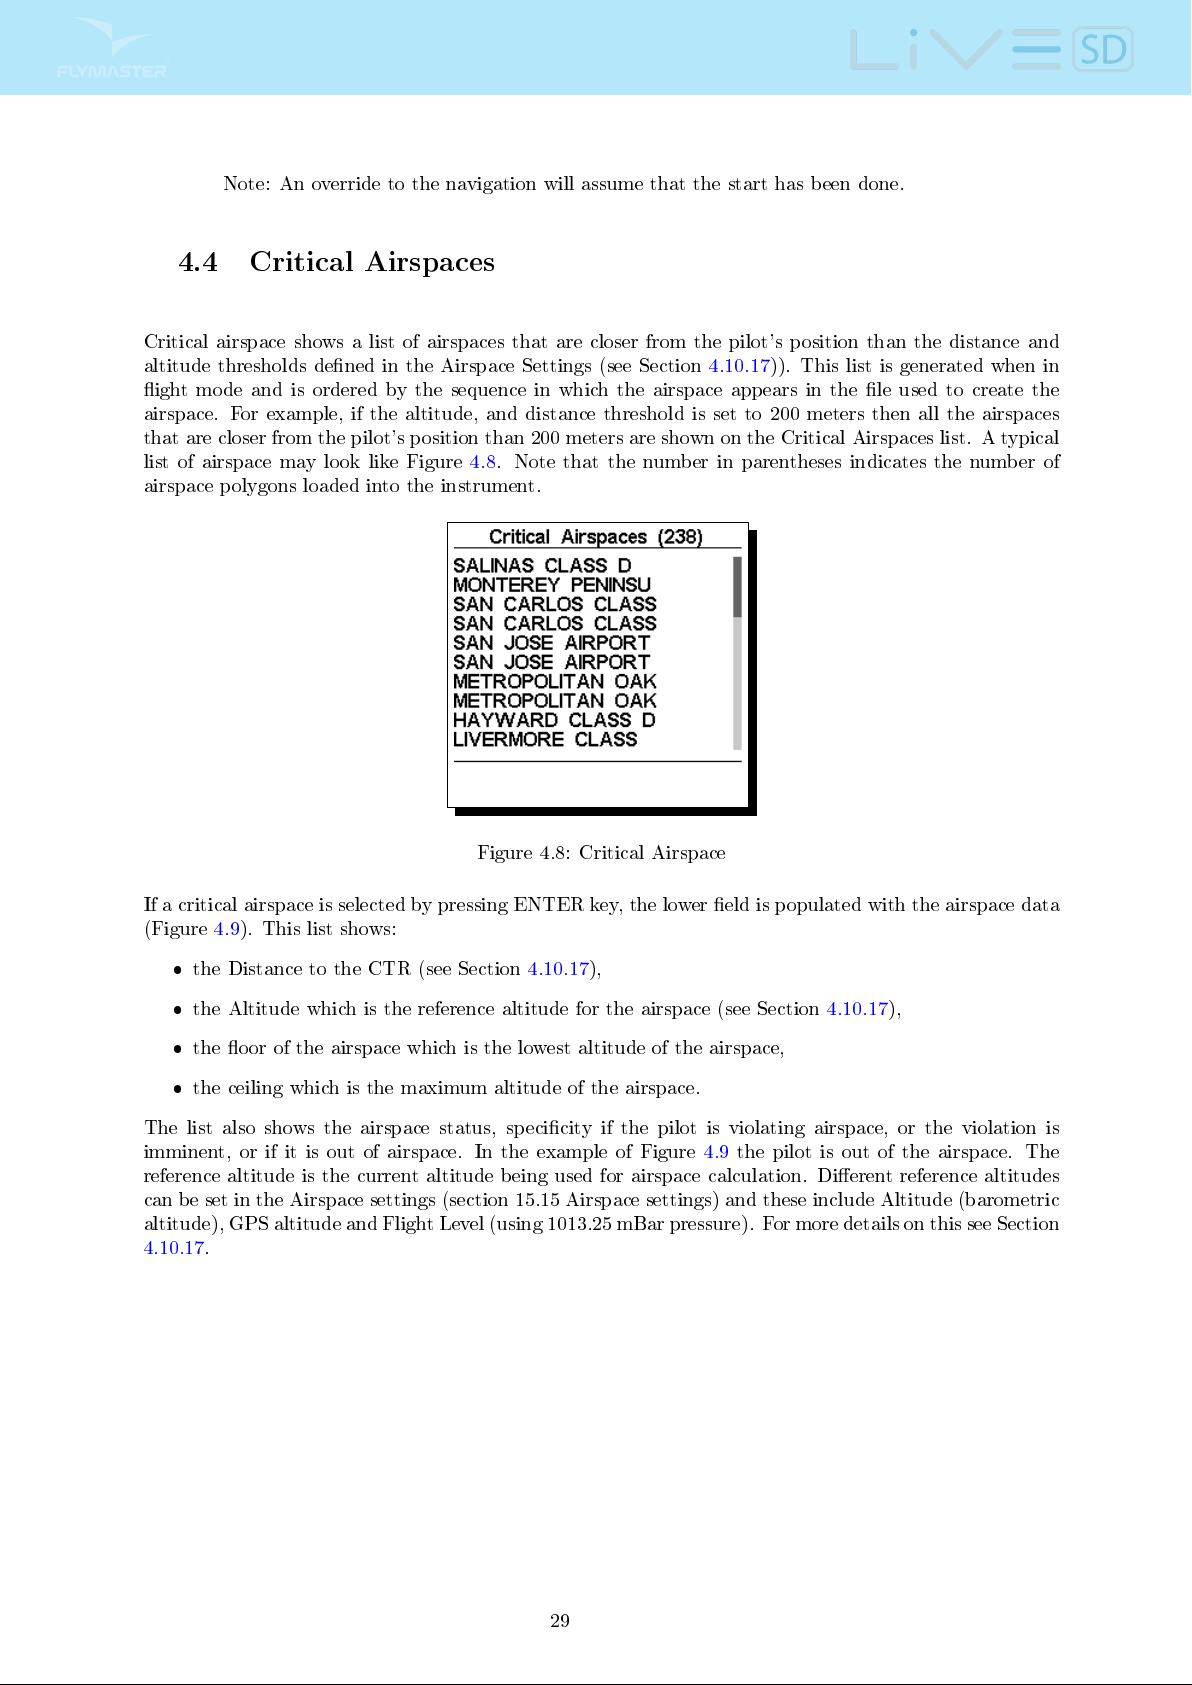
is
Figure 4.7: Task Navigator
When entering into the Task Navigator menu, all of the route points are shown as both the short name
and long name (Figure 4.7). Selecting any of the routepoints will show a navigation wheel in the lower
part of the screen showing the direction to that point along with the distance to the waypoint cylinder.
The distance shown is the Distance to Line, which is the closest point on the cylinder to where the pilot
is. This is not necessarily the optimum point on the cylinder.
The
Start
waypoint will be grayed since it is not possible to navigate to a start. Pressing the menu button
will get you back to the ight screen without any change to the navigation.
28
Page 30
Note: An override to the navigation will assume that the start has been done.
4.4 Critical Airspaces
Critical airspace shows a list of airspaces that are closer from the pilot's position than the distance and
altitude thresholds dened in the Airspace Settings (see Section 4.10.17)). This list is generated when in
ight mode and is ordered by the sequence in which the airspace appears in the le used to create the
airspace. For example, if the altitude, and distance threshold is set to 200 meters then all the airspaces
that are closer from the pilot's position than 200 meters are shown on the Critical Airspaces list. A typical
list of airspace may look like Figure 4.8. Note that the number in parentheses indicates the number of
airspace polygons loaded into the instrument.
Figure 4.8: Critical Airspace
If a critical airspace is selected by pressing ENTER key, the lower eld is populated with the airspace data
(Figure 4.9). This list shows:
the Distance to the CTR (see Section 4.10.17),
the Altitude which is the reference altitude for the airspace (see Section 4.10.17),
the oor of the airspace which is the lowest altitude of the airspace,
the ceiling which is the maximum altitude of the airspace.
The list also shows the airspace status, specicity if the pilot is violating airspace, or the violation is
imminent, or if it is out of airspace. In the example of Figure 4.9 the pilot is out of the airspace. The
reference altitude is the current altitude being used for airspace calculation. Dierent reference altitudes
can be set in the Airspace settings (section 15.15 Airspace settings) and these include Altitude (barometric
altitude), GPS altitude and Flight Level (using 1013.25 mBar pressure). For more details on this see Section
4.10.17.
29
Page 31
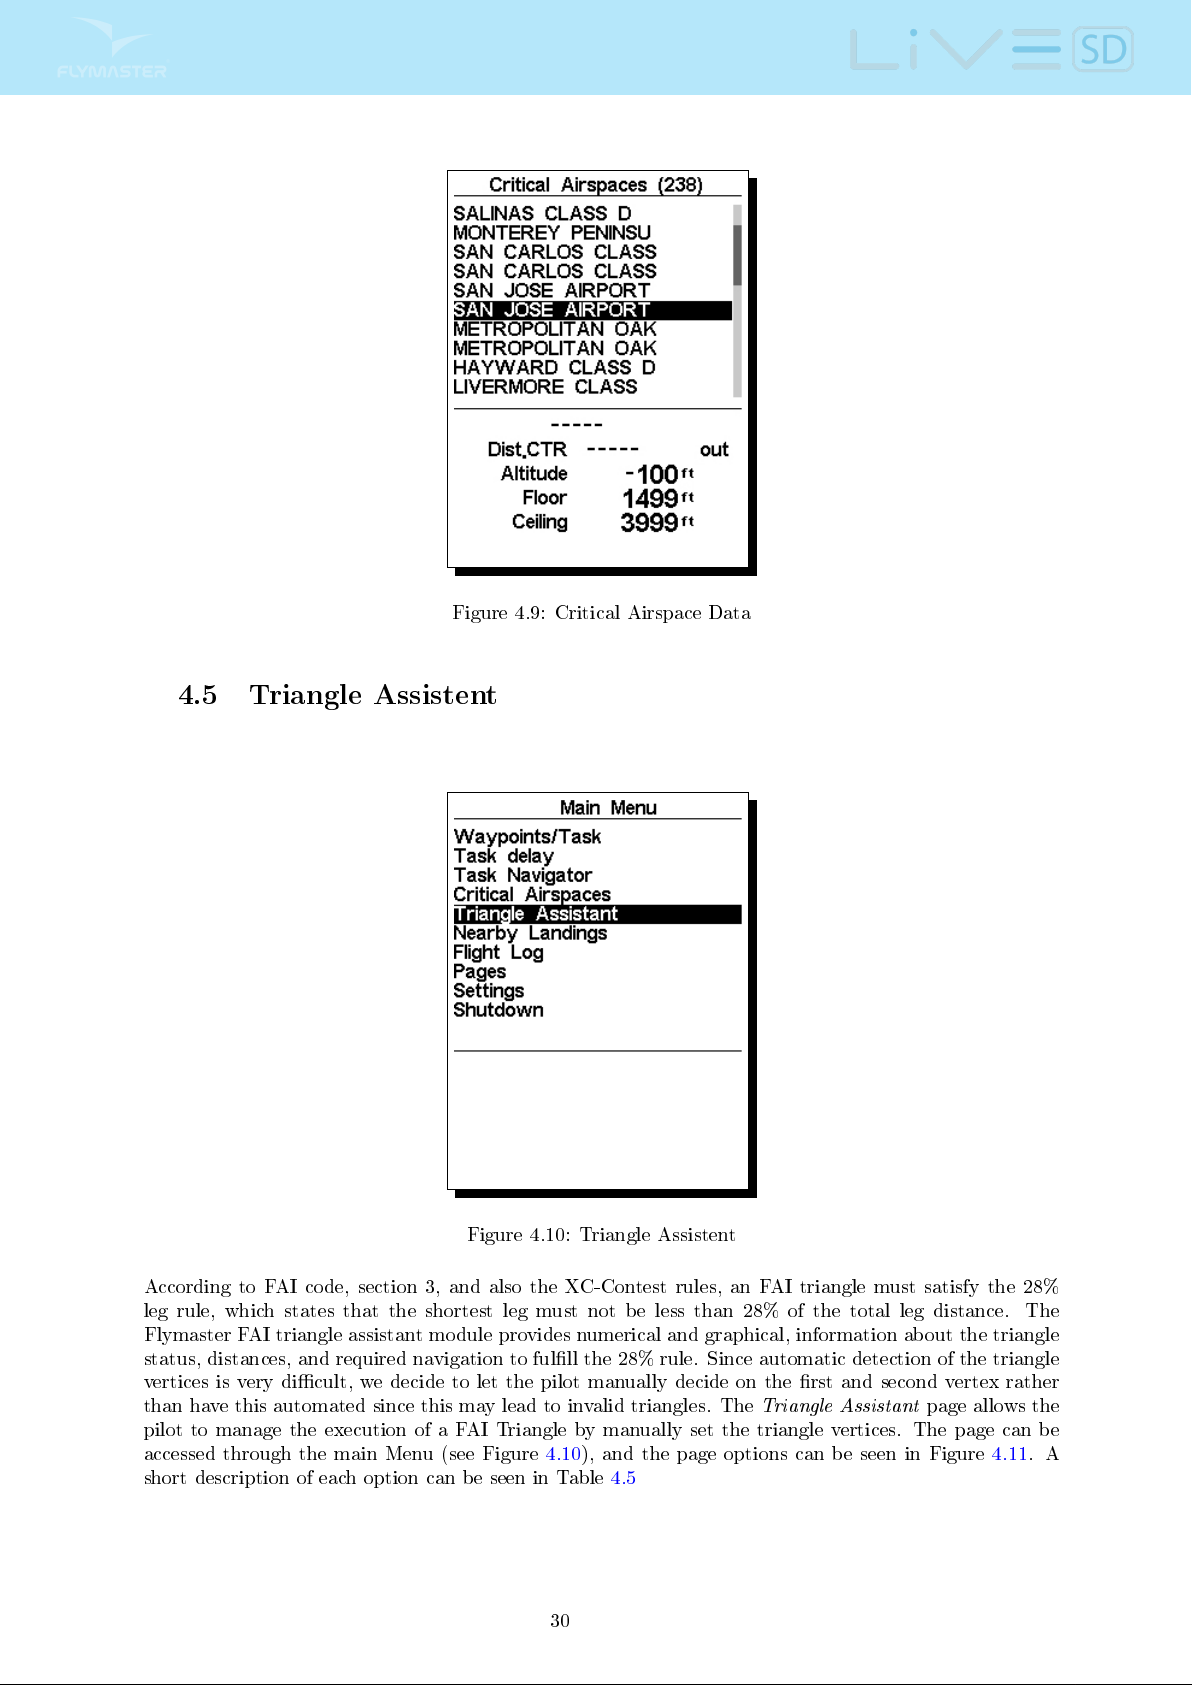
Figure 4.9: Critical Airspace Data
4.5 Triangle Assistent
Figure 4.10: Triangle Assistent
According to FAI code, section 3, and also the XC-Contest rules, an FAI triangle must satisfy the 28%
leg rule, which states that the shortest leg must not be less than 28% of the total leg distance. The
Flymaster FAI triangle assistant module provides numerical and graphical, information about the triangle
status, distances, and required navigation to fulll the 28% rule. Since automatic detection of the triangle
vertices is very dicult, we decide to let the pilot manually decide on the rst and second vertex rather
than have this automated since this may lead to invalid triangles. The
pilot to manage the execution of a FAI Triangle by manually set the triangle vertices. The page can be
accessed through the main Menu (see Figure 4.10), and the page options can be seen in Figure 4.11. A
short description of each option can be seen in Table 4.5
30
Triangle Assistant
page allows the
Page 32
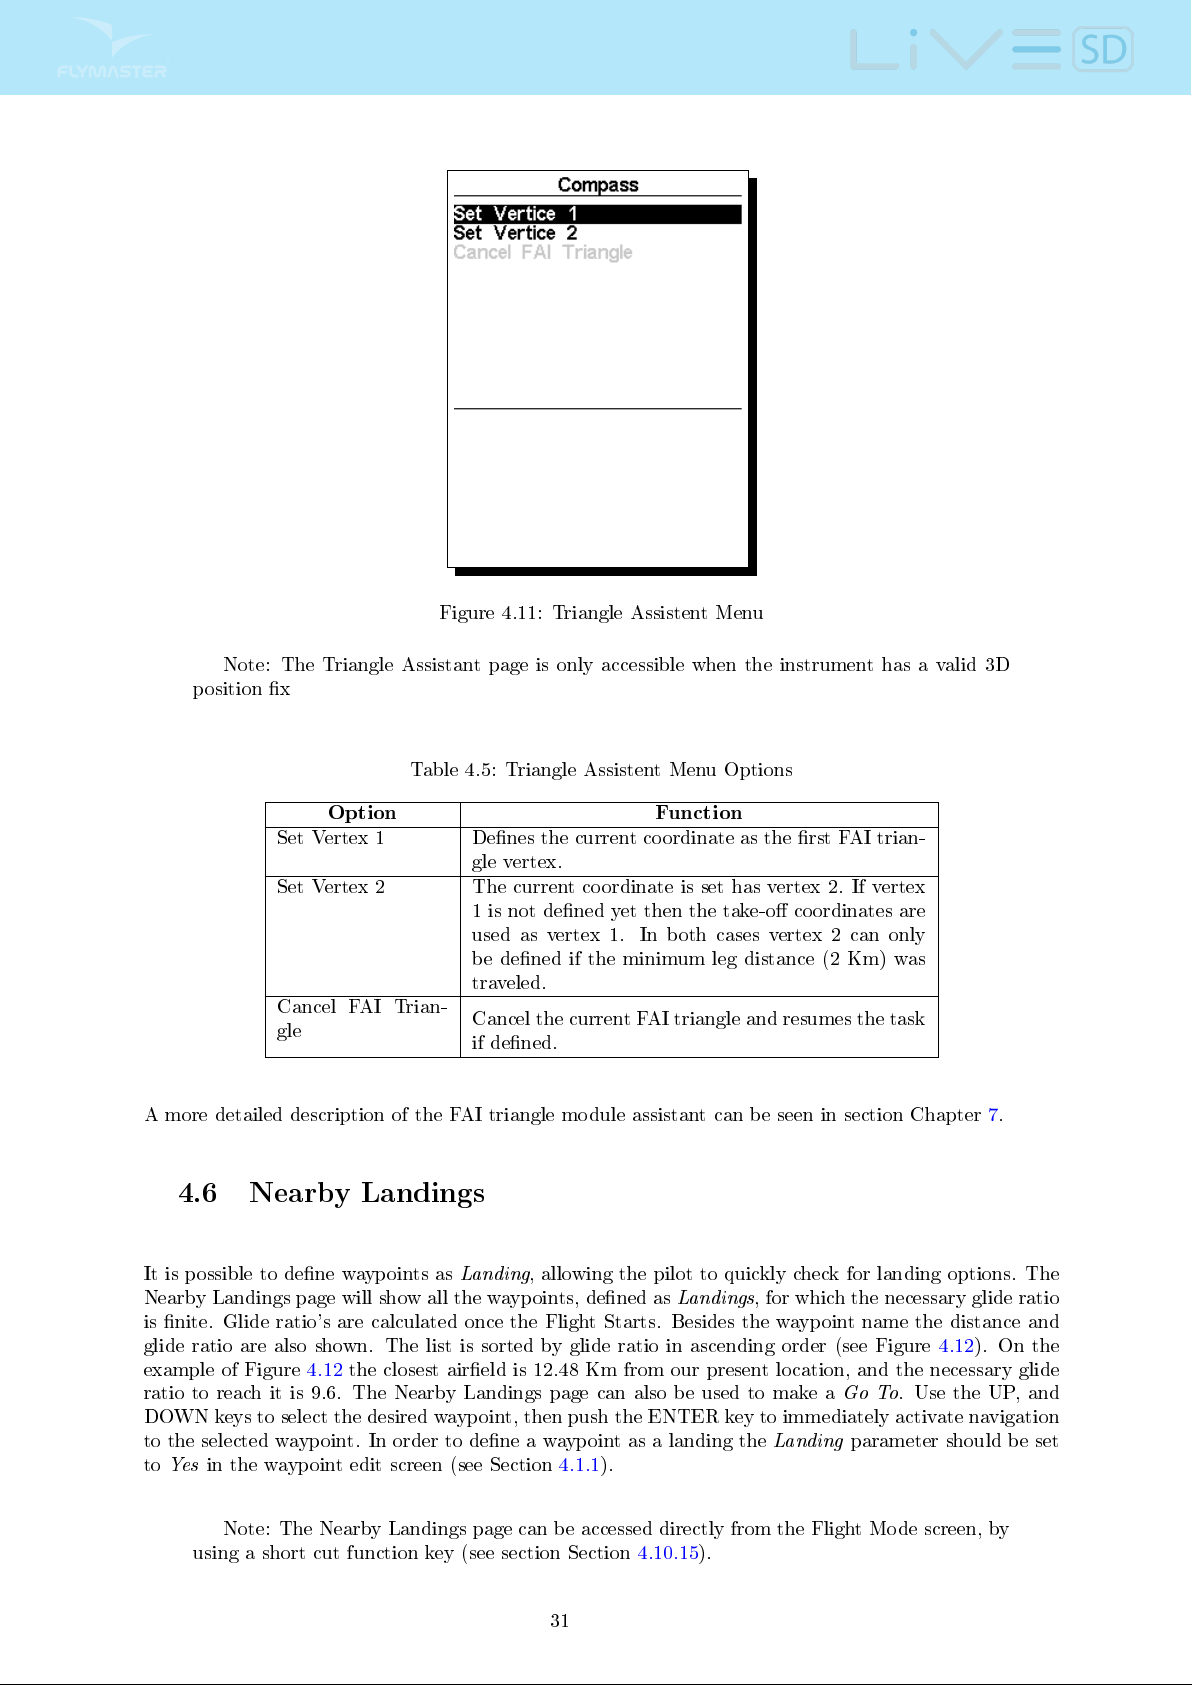
Figure 4.11: Triangle Assistent Menu
Note: The Triangle Assistant page is only accessible when the instrument has a valid 3D
position x
Table 4.5: Triangle Assistent Menu Options
Option Function
Set Vertex 1
Set Vertex 2
Cancel FAI Trian-
gle
A more detailed description of the FAI triangle module assistant can be seen in section Chapter 7.
Denes the current coordinate as the rst FAI trian-
gle vertex.
The current coordinate is set has vertex 2. If vertex
1 is not dened yet then the take-o coordinates are
used as vertex 1. In both cases vertex 2 can only
be dened if the minimum leg distance (2 Km) was
traveled.
Cancel the current FAI triangle and resumes the task
if dened.
4.6 Nearby Landings
It is possible to dene waypoints as
Nearby Landings page will show all the waypoints, dened as
is nite. Glide ratio's are calculated once the Flight Starts. Besides the waypoint name the distance and
glide ratio are also shown. The list is sorted by glide ratio in ascending order (see Figure 4.12). On the
example of Figure 4.12 the closest aireld is 12.48 Km from our present location, and the necessary glide
ratio to reach it is 9.6. The Nearby Landings page can also be used to make a
DOWN keys to select the desired waypoint, then push the ENTER key to immediately activate navigation
to the selected waypoint. In order to dene a waypoint as a landing the
to
Yes
in the waypoint edit screen (see Section 4.1.1).
Note: The Nearby Landings page can be accessed directly from the Flight Mode screen, by
using a short cut function key (see section Section 4.10.15).
Landing
, allowing the pilot to quickly check for landing options. The
Landings
31
, for which the necessary glide ratio
Go To
. Use the UP, and
Landing
parameter should be set
Page 33
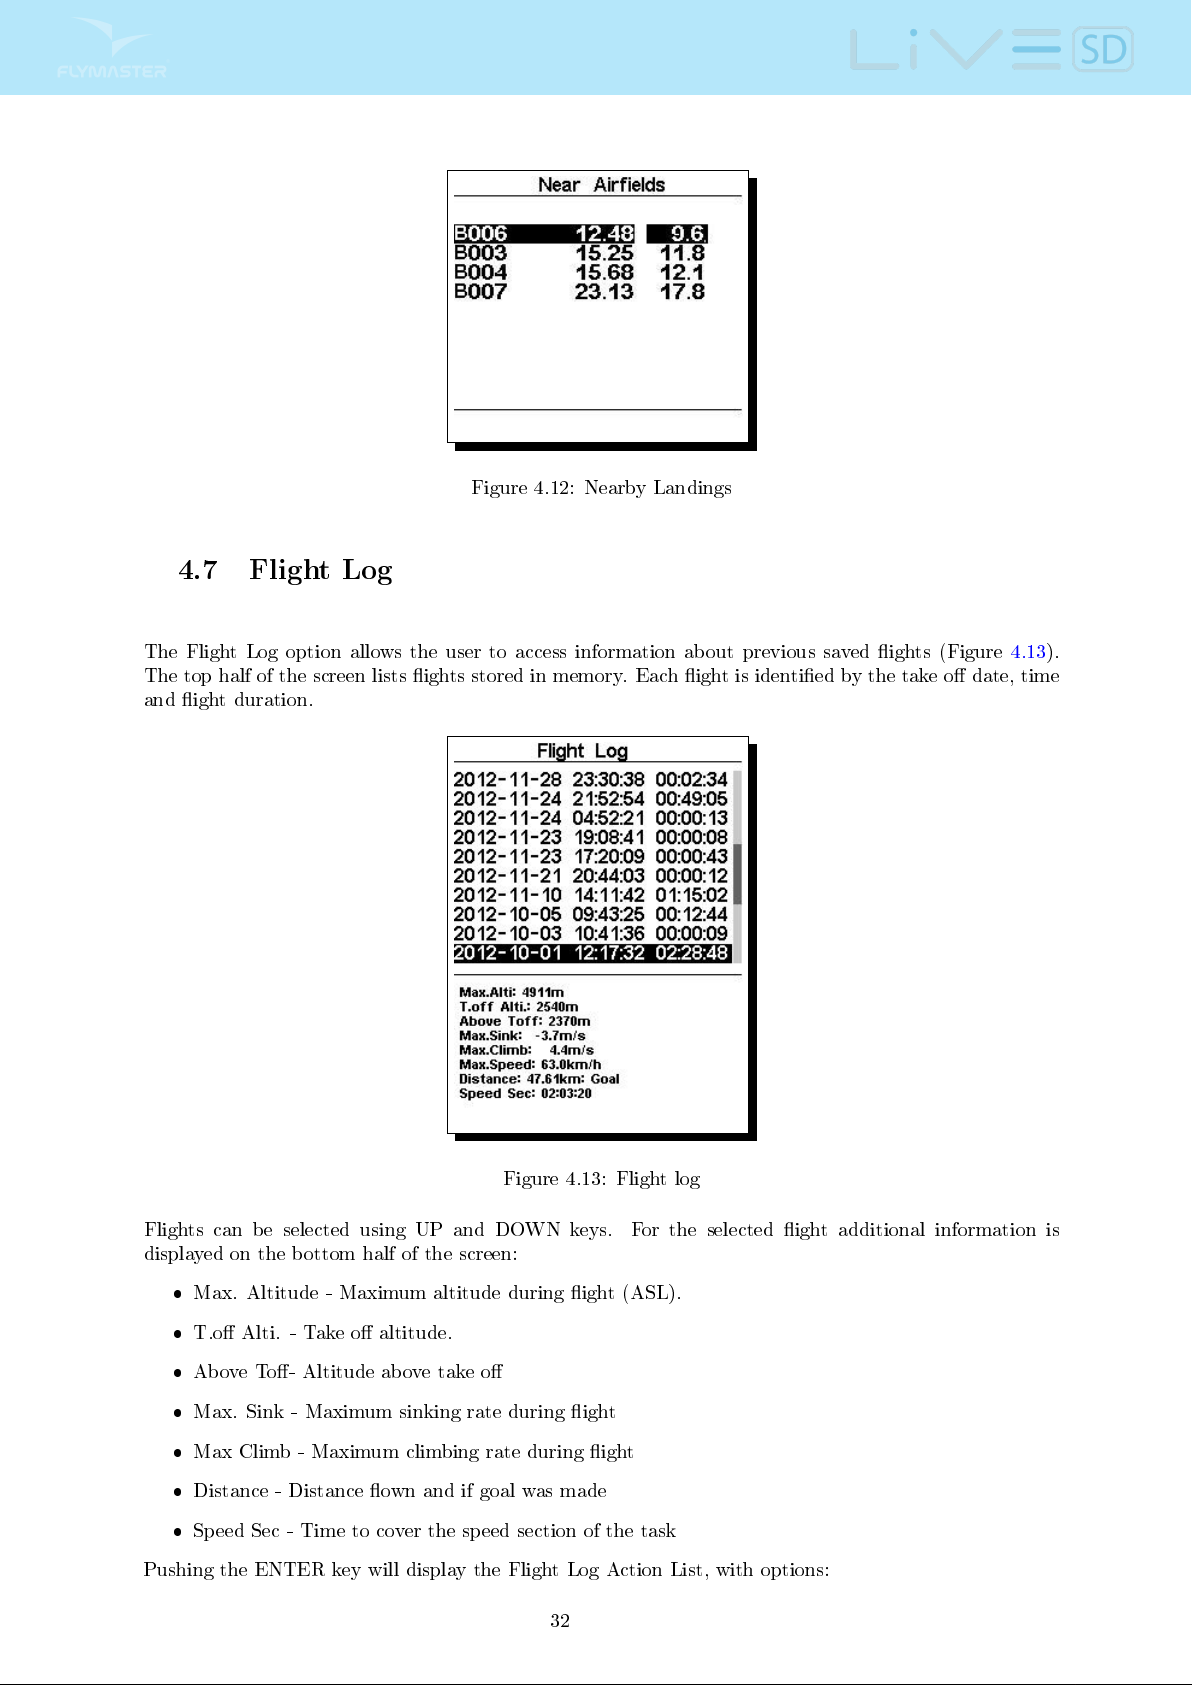
Figure 4.12: Nearby Landings
4.7 Flight Log
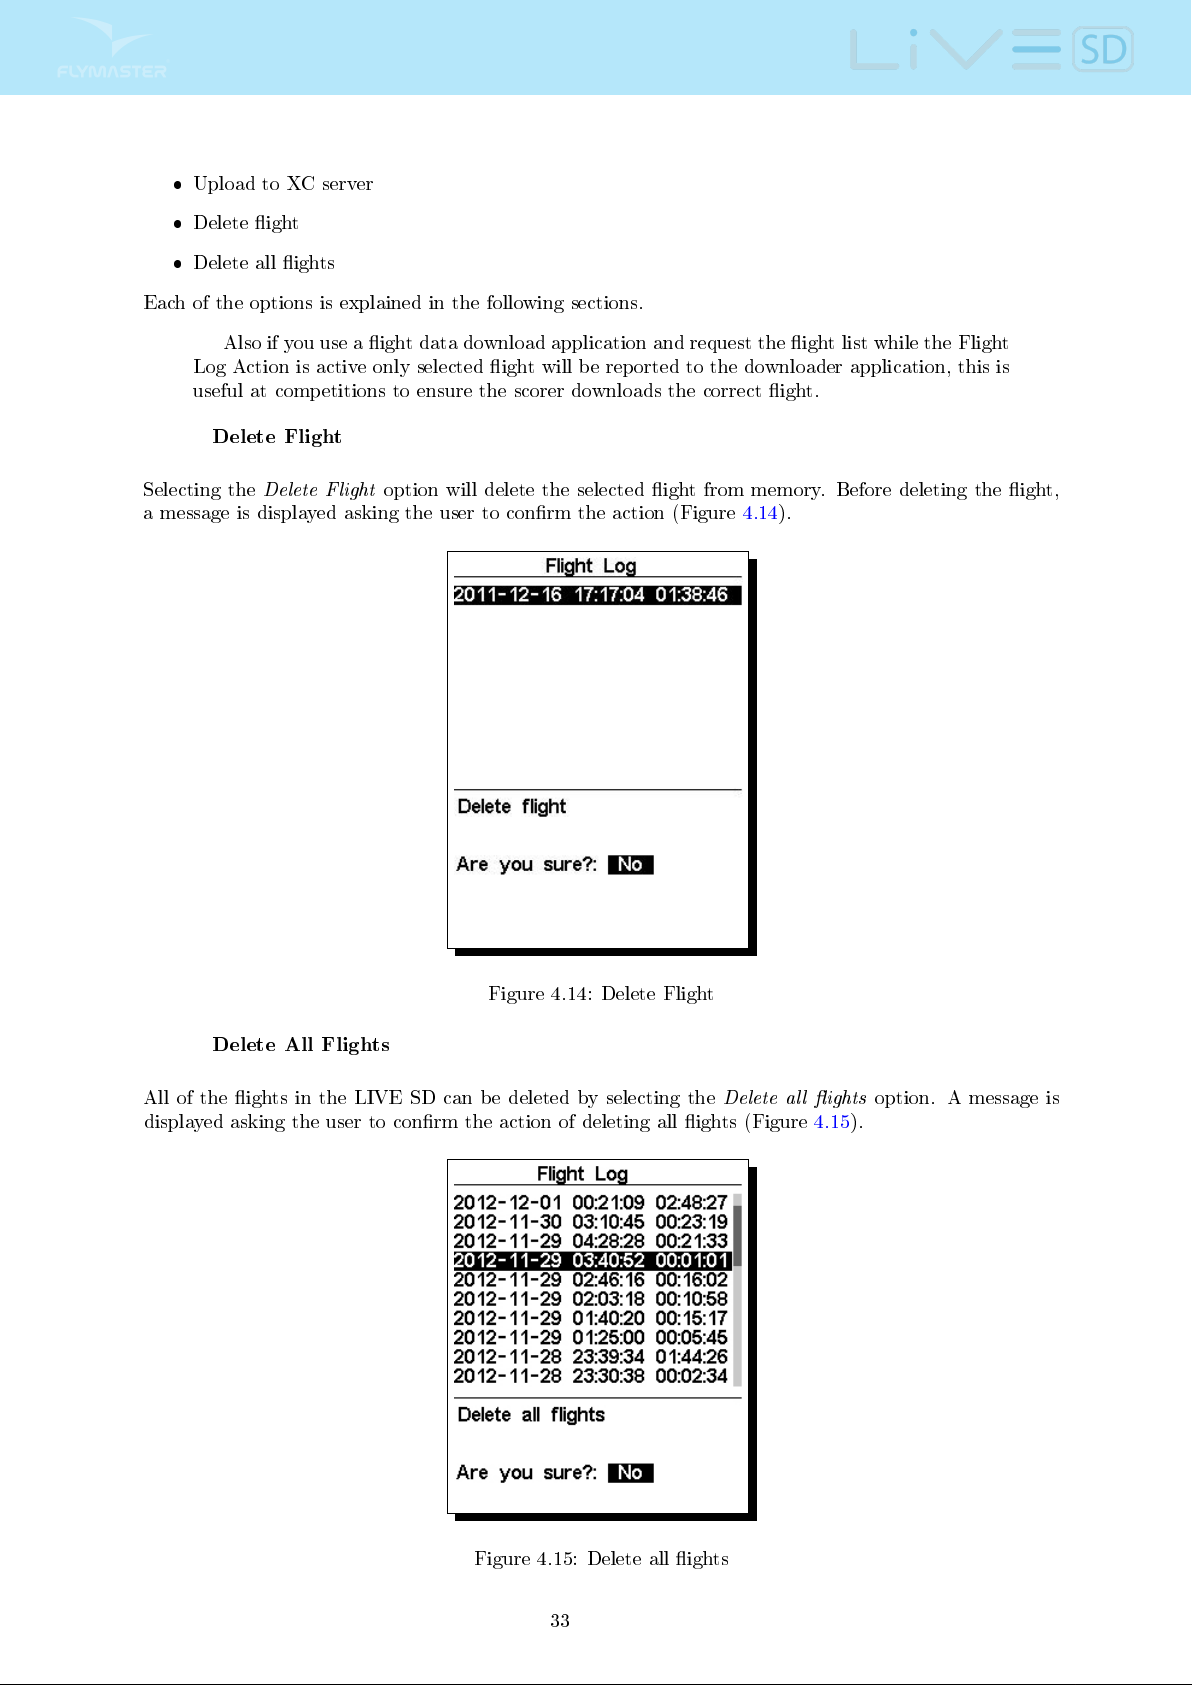
The Flight Log option allows the user to access information about previous saved ights (Figure 4.13).
The top half of the screen lists ights stored in memory. Each ight is identied by the take o date, time
and ight duration.
Figure 4.13: Flight log
Flights can be selected using UP and DOWN keys. For the selected ight additional information is
displayed on the bottom half of the screen:
Max. Altitude - Maximum altitude during ight (ASL).
T.o Alti. - Take o altitude.
Above To- Altitude above take o
Max. Sink - Maximum sinking rate during ight
Max Climb - Maximum climbing rate during ight
Distance - Distance own and if goal was made
Speed Sec - Time to cover the speed section of the task
Pushing the ENTER key will display the Flight Log Action List, with options:
32
Page 34
Upload to XC server
Delete ight
Delete all ights
Each of the options is explained in the following sections.
Also if you use a ight data download application and request the ight list while the Flight
Log Action is active only selected ight will be reported to the downloader application, this is
useful at competitions to ensure the scorer downloads the correct ight.
Delete Flight
Selecting the
Delete Flight
option will delete the selected ight from memory. Before deleting the ight,
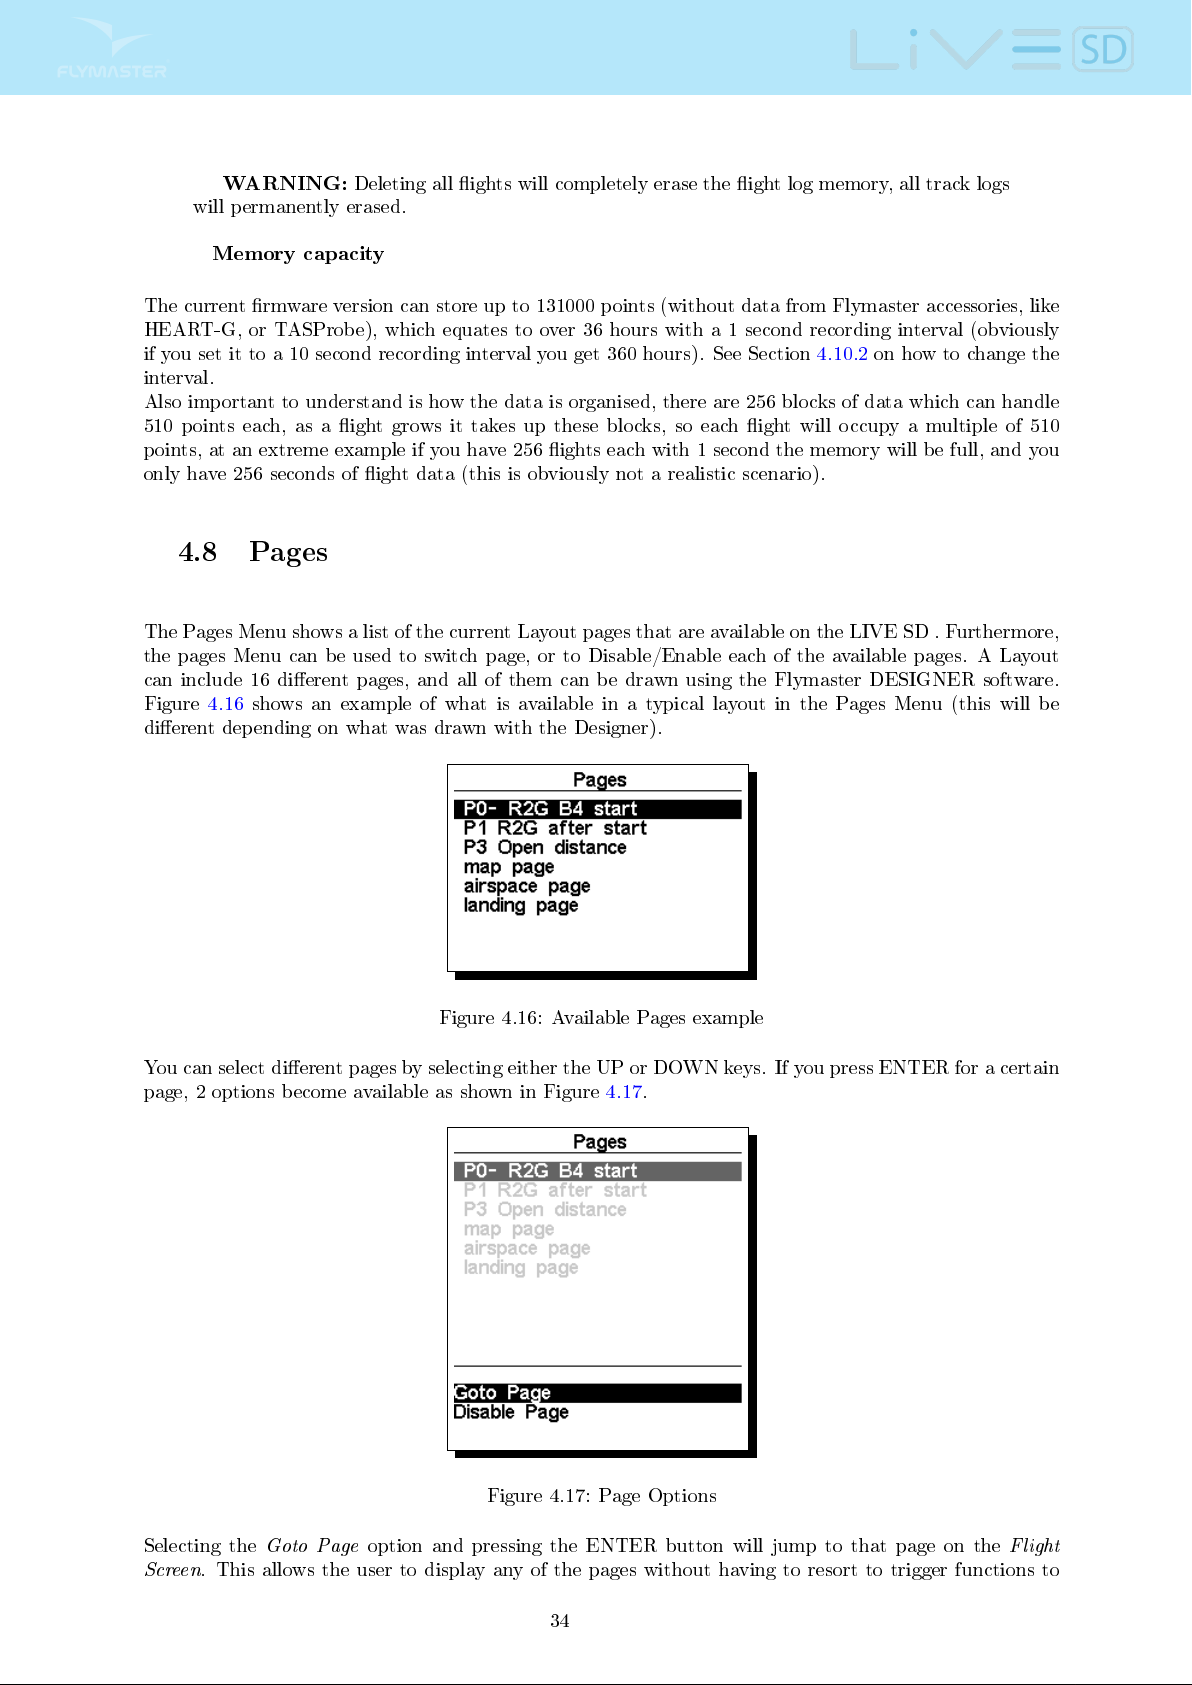
a message is displayed asking the user to conrm the action (Figure 4.14).
Figure 4.14: Delete Flight
Delete All Flights
All of the ights in the LIVE SD can be deleted by selecting the
Delete all ights
displayed asking the user to conrm the action of deleting all ights (Figure 4.15).
Figure 4.15: Delete all ights
33
option. A message is
Page 35
WARNING:
will permanently erased.
Memory capacity
The current rmware version can store up to 131000 points (without data from Flymaster accessories, like
HEART-G, or TASProbe), which equates to over 36 hours with a 1 second recording interval (obviously
if you set it to a 10 second recording interval you get 360 hours). See Section 4.10.2 on how to change the
interval.
Also important to understand is how the data is organised, there are 256 blocks of data which can handle
510 points each, as a ight grows it takes up these blocks, so each ight will occupy a multiple of 510
points, at an extreme example if you have 256 ights each with 1 second the memory will be full, and you
only have 256 seconds of ight data (this is obviously not a realistic scenario).
Deleting all ights will completely erase the ight log memory, all track logs
4.8 Pages
The Pages Menu shows a list of the current Layout pages that are available on the LIVE SD . Furthermore,
the pages Menu can be used to switch page, or to Disable/Enable each of the available pages. A Layout
can include 16 dierent pages, and all of them can be drawn using the Flymaster DESIGNER software.
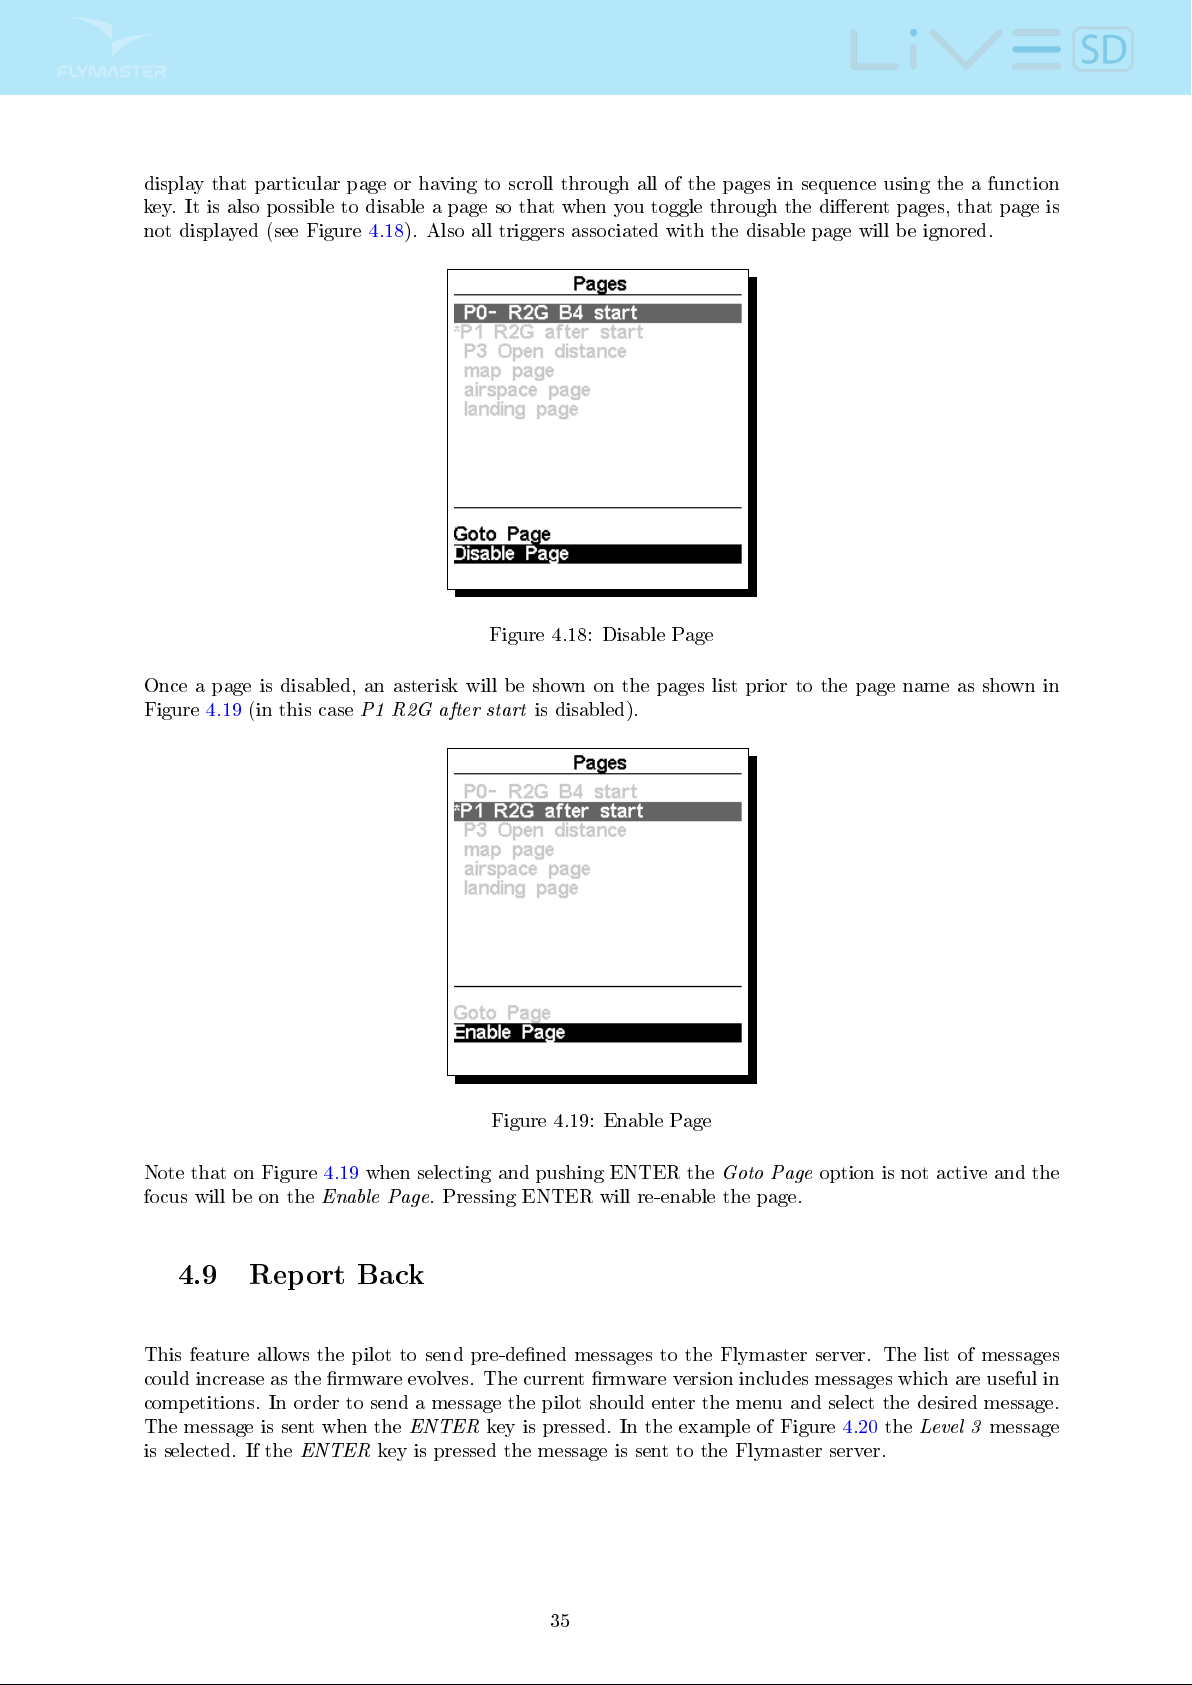
Figure 4.16 shows an example of what is available in a typical layout in the Pages Menu (this will be
dierent depending on what was drawn with the Designer).
Figure 4.16: Available Pages example
You can select dierent pages by selecting either the UP or DOWN keys. If you press ENTER for a certain
page, 2 options become available as shown in Figure 4.17.
Figure 4.17: Page Options
Selecting the
Screen
. This allows the user to display any of the pages without having to resort to trigger functions to
Goto Page
option and pressing the ENTER button will jump to that page on the
Flight
34
Page 36
display that particular page or having to scroll through all of the pages in sequence using the a function
key. It is also possible to disable a page so that when you toggle through the dierent pages, that page is
not displayed (see Figure 4.18). Also all triggers associated with the disable page will be ignored.
Figure 4.18: Disable Page
Once a page is disabled, an asterisk will be shown on the pages list prior to the page name as shown in
Figure 4.19 (in this case
P1 R2G after start
is disabled).
Figure 4.19: Enable Page
Note that on Figure 4.19 when selecting and pushing ENTER the
focus will be on the
Enable Page
. Pressing ENTER will re-enable the page.
Goto Page
option is not active and the
4.9 Report Back
This feature allows the pilot to send pre-dened messages to the Flymaster server. The list of messages
could increase as the rmware evolves. The current rmware version includes messages which are useful in
competitions. In order to send a message the pilot should enter the menu and select the desired message.
The message is sent when the
is selected. If the
ENTER
ENTER
key is pressed the message is sent to the Flymaster server.
key is pressed. In the example of Figure 4.20 the
35
Level 3
message
Page 37
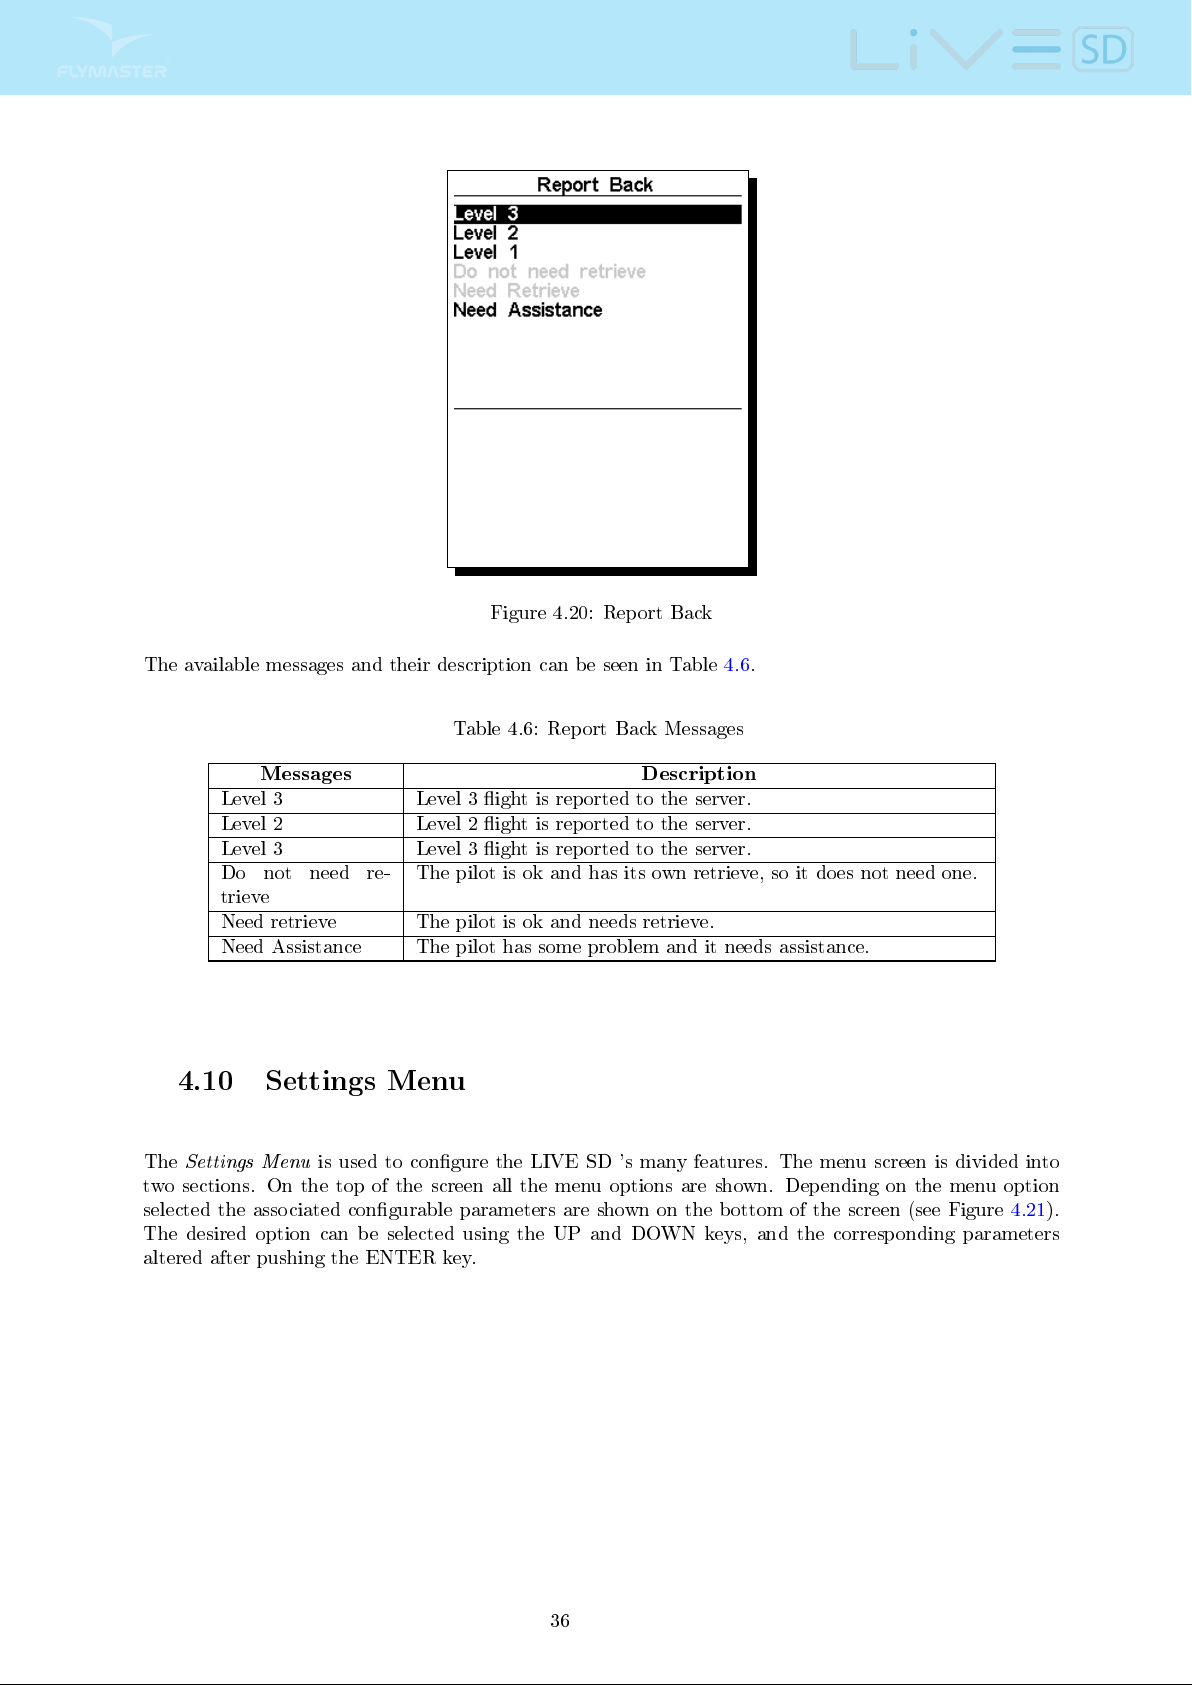
Figure 4.20: Report Back
The available messages and their description can be seen in Table 4.6.
Table 4.6: Report Back Messages
Messages Description
Level 3 Level 3 ight is reported to the server.
Level 2 Level 2 ight is reported to the server.
Level 3 Level 3 ight is reported to the server.
Do not need re-
trieve
Need retrieve The pilot is ok and needs retrieve.
Need Assistance The pilot has some problem and it needs assistance.
The pilot is ok and has its own retrieve, so it does not need one.
4.10 Settings Menu
The
Settings Menu
two sections. On the top of the screen all the menu options are shown. Depending on the menu option
selected the associated congurable parameters are shown on the bottom of the screen (see Figure 4.21).
The desired option can be selected using the UP and DOWN keys, and the corresponding parameters
altered after pushing the ENTER key.
is used to congure the LIVE SD 's many features. The menu screen is divided into
36
Page 38
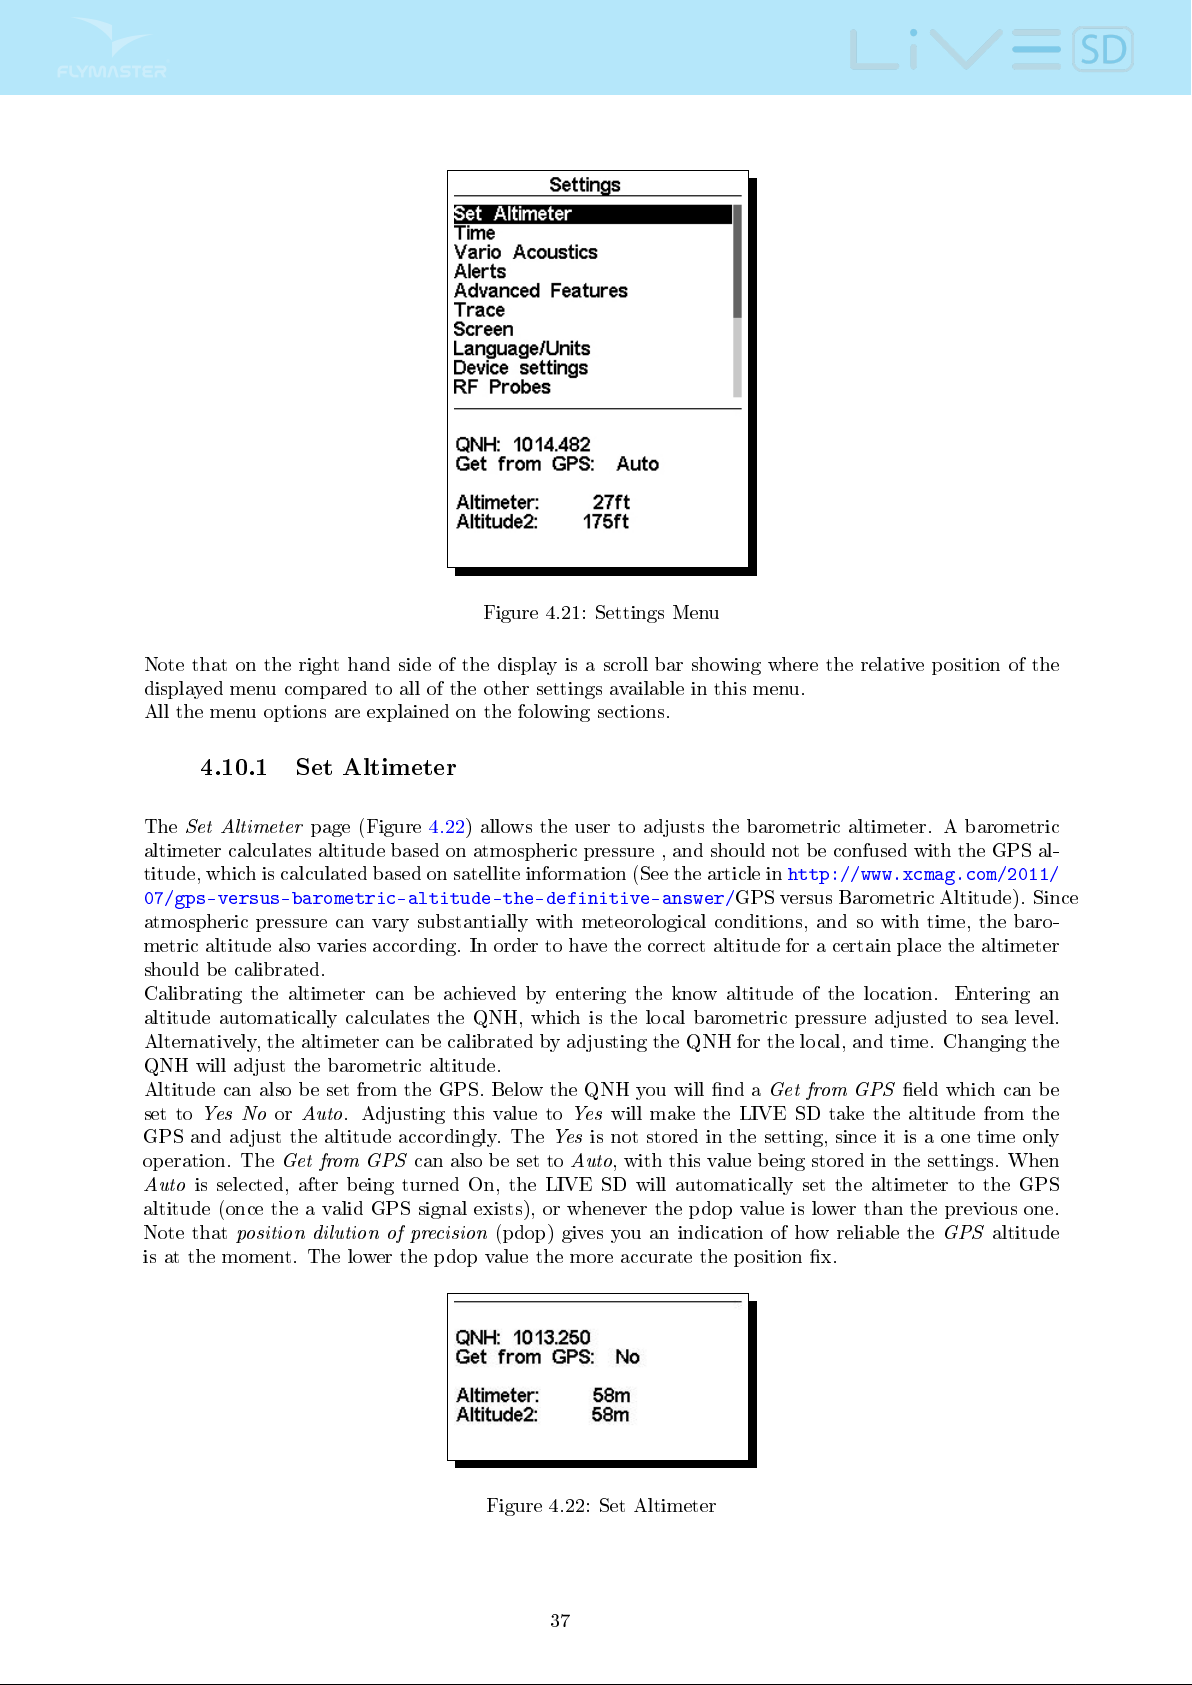
Figure 4.21: Settings Menu
Note that on the right hand side of the display is a scroll bar showing where the relative position of the
displayed menu compared to all of the other settings available in this menu.
All the menu options are explained on the folowing sections.
4.10.1 Set Altimeter
The
Set Altimeter
altimeter calculates altitude based on atmospheric pressure , and should not be confused with the GPS al-
titude, which is calculated based on satellite information (See the article in
07/gps-versus-barometric-altitude-the-definitive-answer/
atmospheric pressure can vary substantially with meteorological conditions, and so with time, the baro-
metric altitude also varies according. In order to have the correct altitude for a certain place the altimeter
should be calibrated.
Calibrating the altimeter can be achieved by entering the know altitude of the location. Entering an
altitude automatically calculates the QNH, which is the local barometric pressure adjusted to sea level.
Alternatively, the altimeter can be calibrated by adjusting the QNH for the local, and time. Changing the
QNH will adjust the barometric altitude.
Altitude can also be set from the GPS. Below the QNH you will nd a
set to
Yes NoorAuto
GPS and adjust the altitude accordingly. The
operation. The
Auto
is selected, after being turned On, the LIVE SD will automatically set the altimeter to the GPS
altitude (once the a valid GPS signal exists), or whenever the pdop value is lower than the previous one.
Note that
is at the moment. The lower the pdop value the more accurate the position x.
position dilution of precision
page (Figure 4.22) allows the user to adjusts the barometric altimeter. A barometric
http://www.xcmag.com/2011/
GPS versus Barometric Altitude). Since
. Adjusting this value to
Get from GPS
can also be set to
(pdop) gives you an indication of how reliable the
Get from GPS
Yes
will make the LIVE SD take the altitude from the
Yes
is not stored in the setting, since it is a one time only
Auto
, with this value being stored in the settings. When
eld which can be
GPS
altitude
Figure 4.22: Set Altimeter
37
Page 39
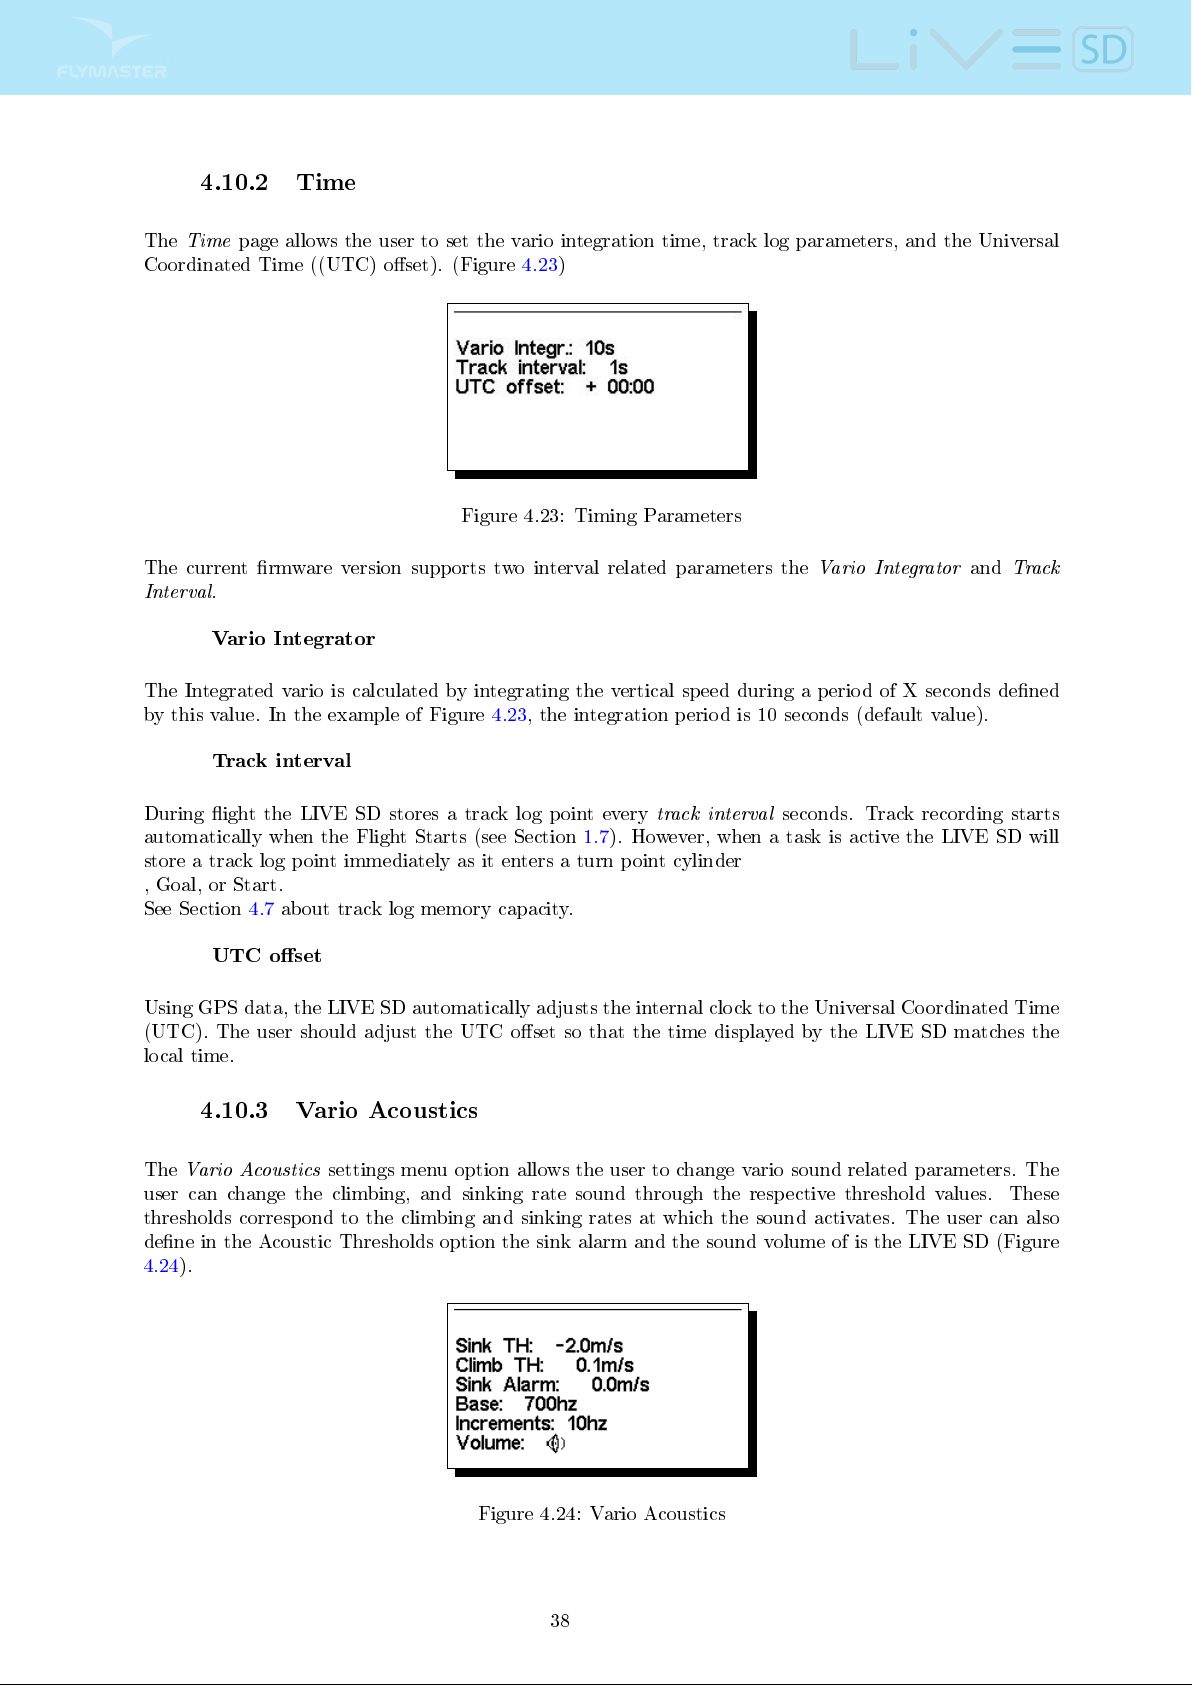
4.10.2 Time
The
Time
page allows the user to set the vario integration time, track log parameters, and the Universal
Coordinated Time ((UTC) oset). (Figure 4.23)
Figure 4.23: Timing Parameters
The current rmware version supports two interval related parameters the
Interval
The Integrated vario is calculated by integrating the vertical speed during a period of X seconds dened
by this value. In the example of Figure 4.23, the integration period is 10 seconds (default value).
During ight the LIVE SD stores a track log point every
automatically when the Flight Starts (see Section 1.7). However, when a task is active the LIVE SD will
store a track log point immediately as it enters a turn point cylinder
, Goal, or Start.
See Section 4.7 about track log memory capacity.
Using GPS data, the LIVE SD automatically adjusts the internal clock to the Universal Coordinated Time
(UTC). The user should adjust the UTC oset so that the time displayed by the LIVE SD matches the
local time.
.
Vario Integrator
Track interval
track interval
UTC oset
Vario Integrator
seconds. Track recording starts
and
Track
4.10.3 Vario Acoustics
The
Vario Acoustics
user can change the climbing, and sinking rate sound through the respective threshold values. These
thresholds correspond to the climbing and sinking rates at which the sound activates. The user can also
dene in the Acoustic Thresholds option the sink alarm and the sound volume of is the LIVE SD (Figure
4.24).
settings menu option allows the user to change vario sound related parameters. The
Figure 4.24: Vario Acoustics
38
Page 40
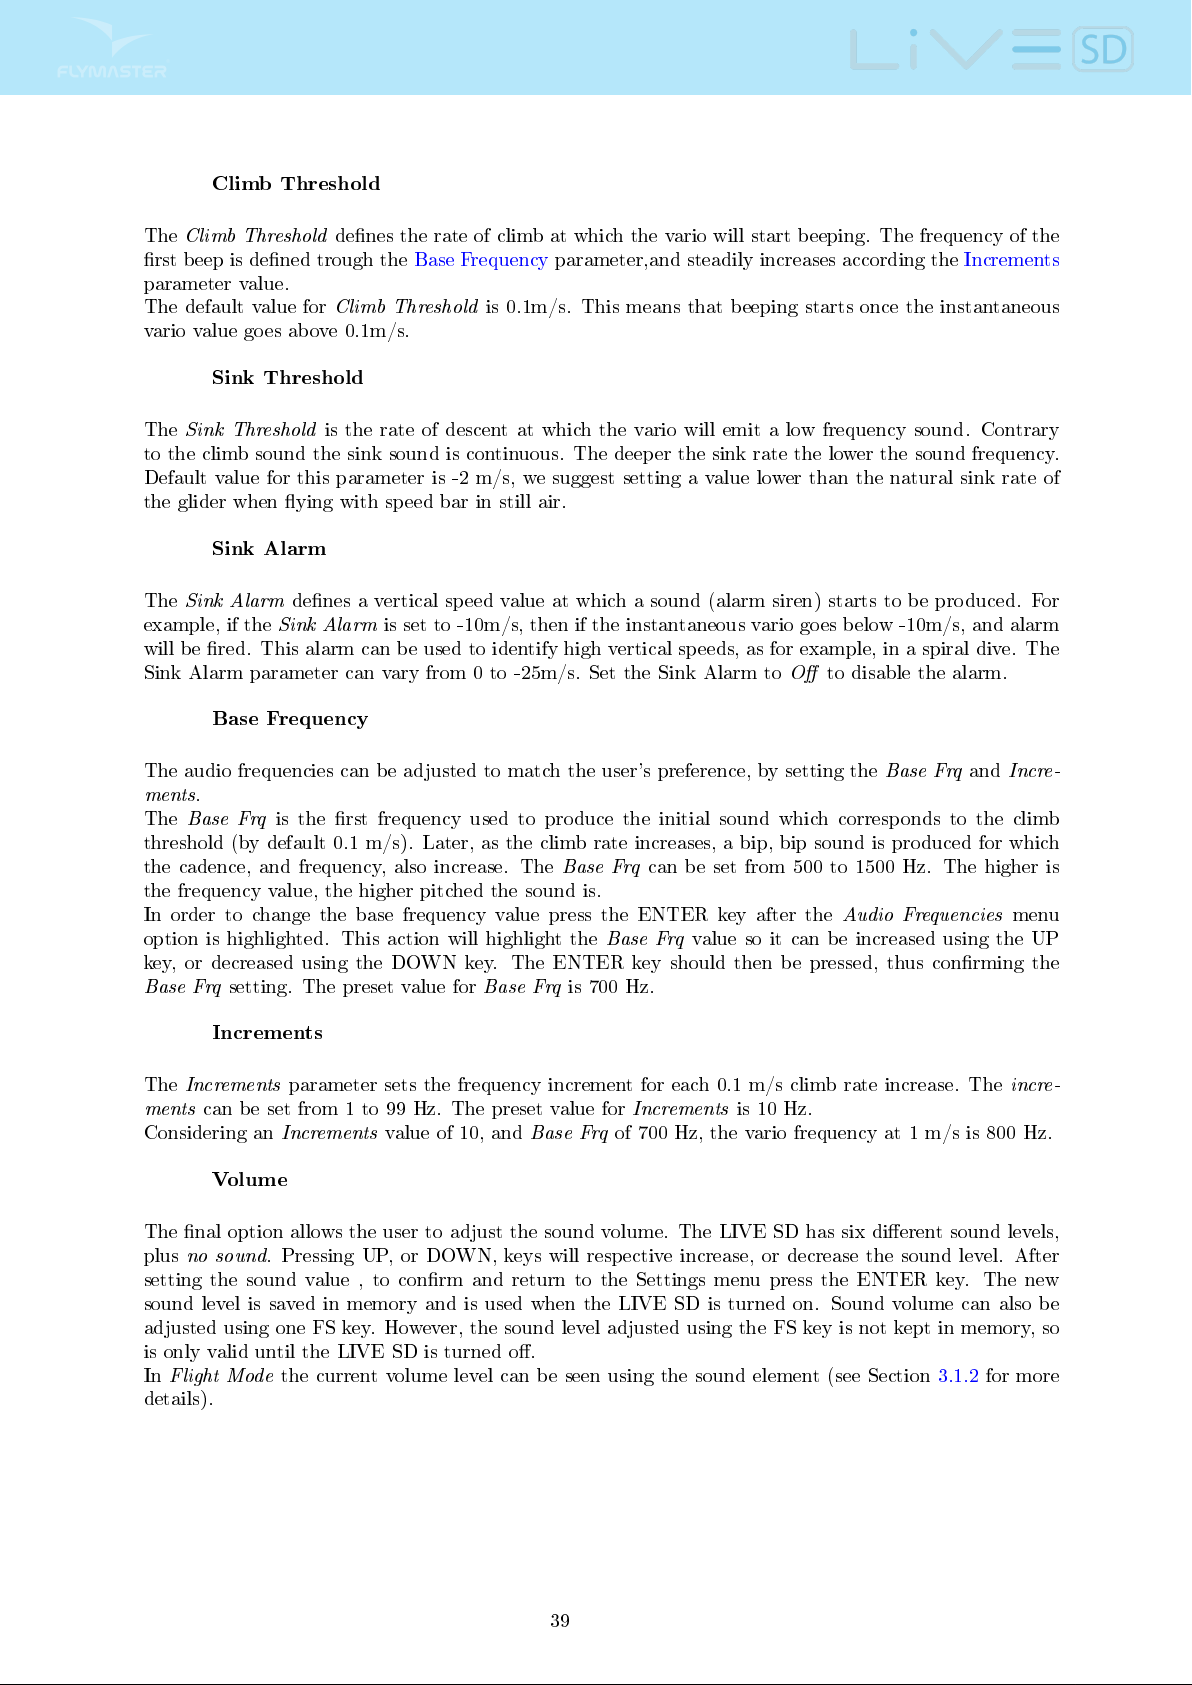
Climb Threshold
The
Climb Threshold
denes the rate of climb at which the vario will start beeping. The frequency of the
rst beep is dened trough the Base Frequency parameter,and steadily increases according the Increments
parameter value.
The default value for
Climb Threshold
is 0.1m/s. This means that beeping starts once the instantaneous
vario value goes above 0.1m/s.
Sink Threshold
The
Sink Threshold
is the rate of descent at which the vario will emit a low frequency sound. Contrary
to the climb sound the sink sound is continuous. The deeper the sink rate the lower the sound frequency.
Default value for this parameter is -2 m/s, we suggest setting a value lower than the natural sink rate of
the glider when ying with speed bar in still air.
Sink Alarm
The
Sink Alarm
example, if the
denes a vertical speed value at which a sound (alarm siren) starts to be produced. For
Sink Alarm
is set to -10m/s, then if the instantaneous vario goes below -10m/s, and alarm
will be red. This alarm can be used to identify high vertical speeds, as for example, in a spiral dive. The
Sink Alarm parameter can vary from 0 to -25m/s. Set the Sink Alarm to
O
to disable the alarm.
Base Frequency
The audio frequencies can be adjusted to match the user's preference, by setting the
ments
.
The
Base Frq
is the rst frequency used to produce the initial sound which corresponds to the climb
Base Frq
and
Incre-
threshold (by default 0.1 m/s). Later, as the climb rate increases, a bip, bip sound is produced for which
the cadence, and frequency, also increase. The
Base Frq
can be set from 500 to 1500 Hz. The higher is
the frequency value, the higher pitched the sound is.
In order to change the base frequency value press the ENTER key after the
option is highlighted. This action will highlight the
Base Frq
value so it can be increased using the UP
Audio Frequencies
menu
key, or decreased using the DOWN key. The ENTER key should then be pressed, thus conrming the
Base Frq
setting. The preset value for
Base Frq
is 700 Hz.
Increments
The
Increments
ments
can be set from 1 to 99 Hz. The preset value for
Considering an
parameter sets the frequency increment for each 0.1 m/s climb rate increase. The
Increments
value of 10, and
Base Frq
Increments
of 700 Hz, the vario frequency at 1 m/s is 800 Hz.
is 10 Hz.
incre-
Volume
The nal option allows the user to adjust the sound volume. The LIVE SD has six dierent sound levels,
plus
no sound
. Pressing UP, or DOWN, keys will respective increase, or decrease the sound level. After
setting the sound value , to conrm and return to the Settings menu press the ENTER key. The new
sound level is saved in memory and is used when the LIVE SD is turned on. Sound volume can also be
adjusted using one FS key. However, the sound level adjusted using the FS key is not kept in memory, so
is only valid until the LIVE SD is turned o.
In
Flight Mode
the current volume level can be seen using the sound element (see Section 3.1.2 for more
details).
39
Page 41
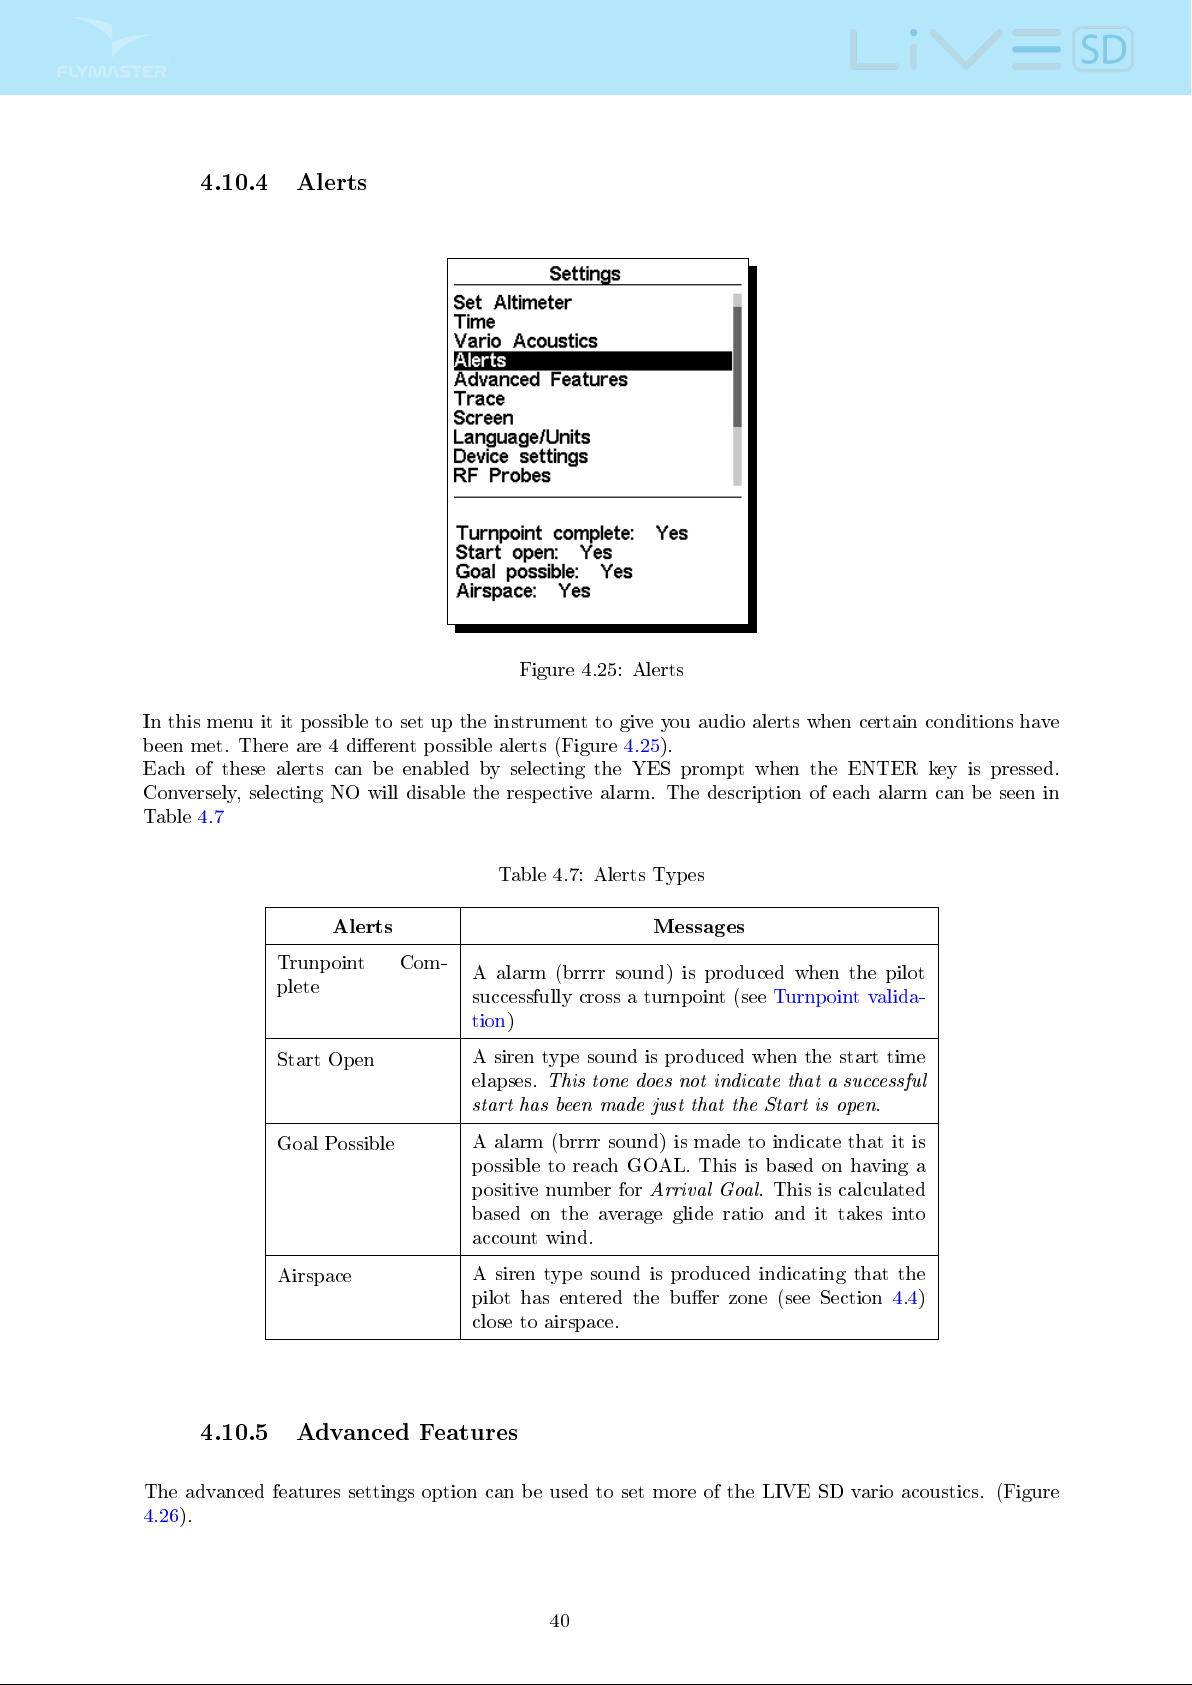
4.10.4 Alerts
Figure 4.25: Alerts
In this menu it it possible to set up the instrument to give you audio alerts when certain conditions have
been met. There are 4 dierent possible alerts (Figure 4.25).
Each of these alerts can be enabled by selecting the YES prompt when the ENTER key is pressed.
Conversely, selecting NO will disable the respective alarm. The description of each alarm can be seen in
Table 4.7
Table 4.7: Alerts Types
Alerts Messages
Trunpoint Com-
plete
Start Open
Goal Possible
Airspace
A alarm (brrrr sound) is produced when the pilot
successfully cross a turnpoint (see Turnpoint valida-
tion)
A siren type sound is produced when the start time
elapses.
start has been made just that the Start is open
A alarm (brrrr sound) is made to indicate that it is
possible to reach GOAL. This is based on having a
positive number for
based on the average glide ratio and it takes into
account wind.
A siren type sound is produced indicating that the
pilot has entered the buer zone (see Section 4.4)
close to airspace.
4.10.5 Advanced Features
This tone does not indicate that a successful
.
Arrival Goal
. This is calculated
The advanced features settings option can be used to set more of the LIVE SD vario acoustics. (Figure
4.26).
40
Page 42
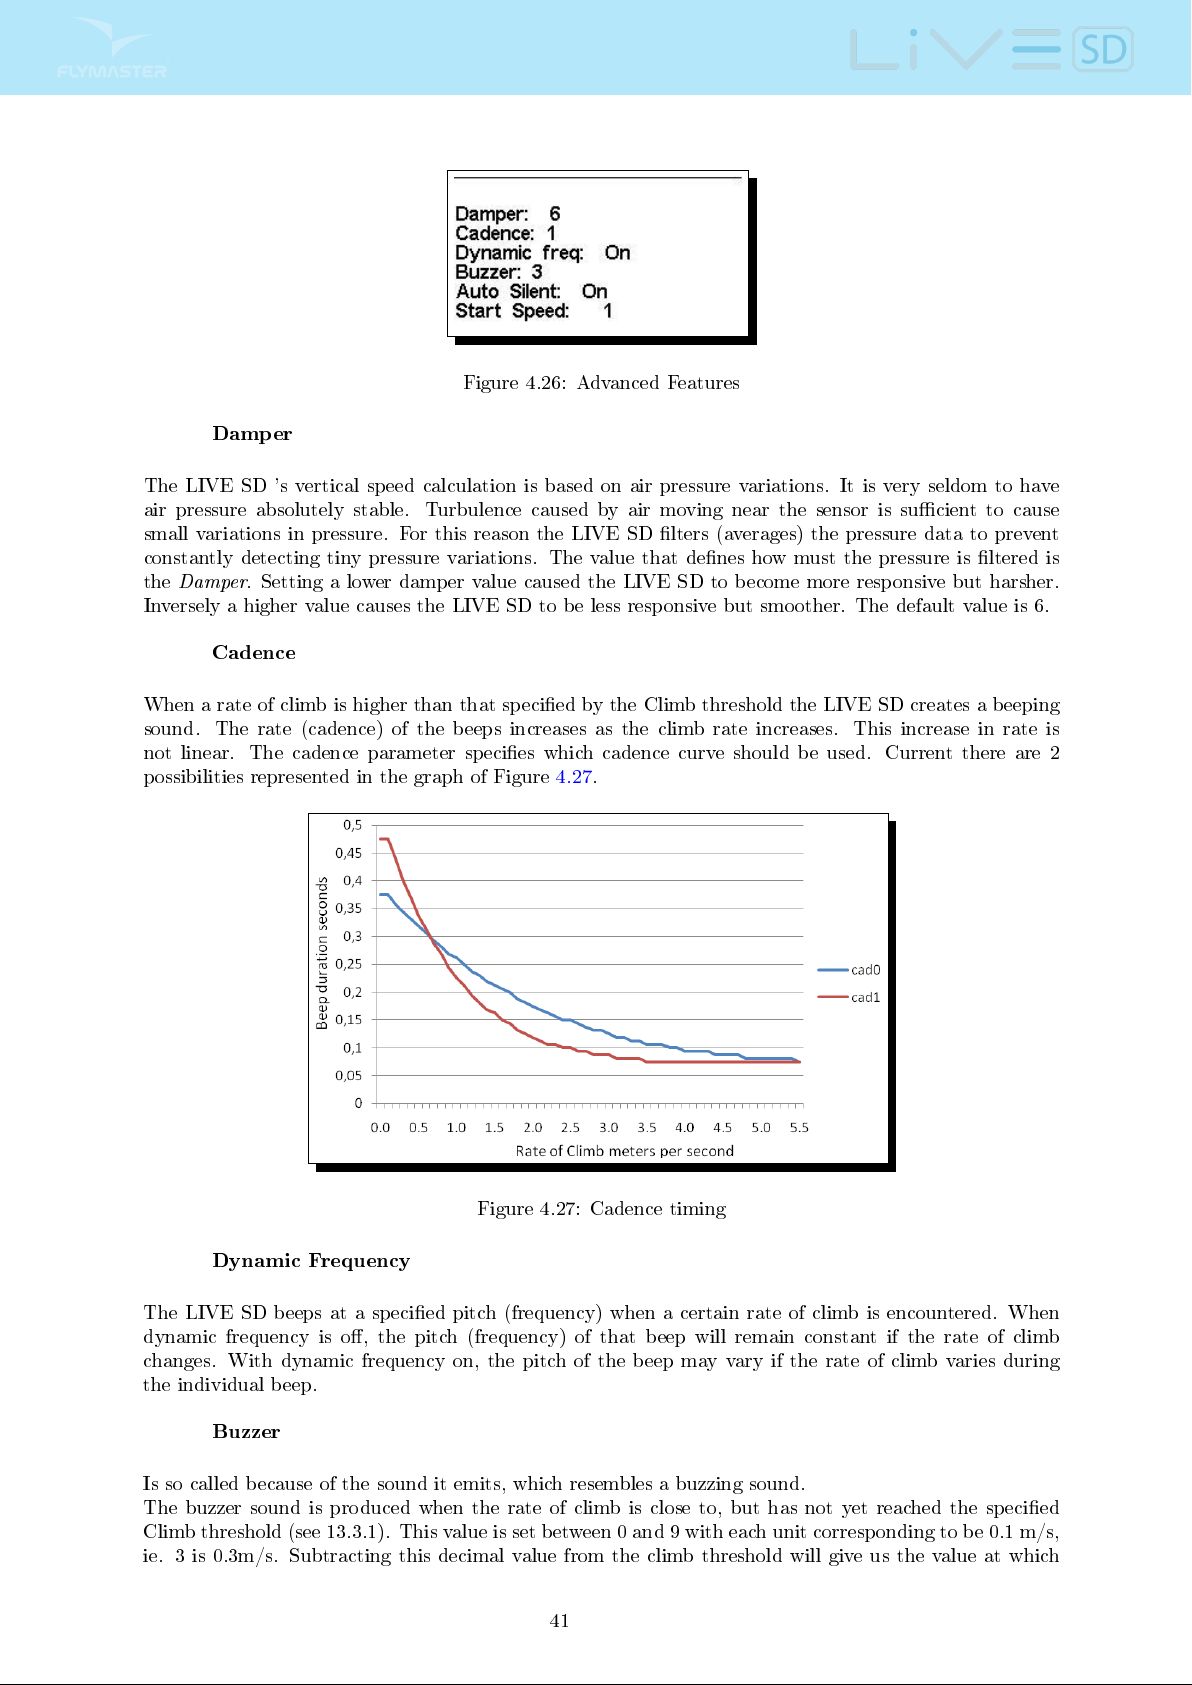
Figure 4.26: Advanced Features
Damper
The LIVE SD 's vertical speed calculation is based on air pressure variations. It is very seldom to have
air pressure absolutely stable. Turbulence caused by air moving near the sensor is sucient to cause
small variations in pressure. For this reason the LIVE SD lters (averages) the pressure data to prevent
constantly detecting tiny pressure variations. The value that denes how must the pressure is ltered is
the
Damper
. Setting a lower damper value caused the LIVE SD to become more responsive but harsher.
Inversely a higher value causes the LIVE SD to be less responsive but smoother. The default value is 6.
Cadence
When a rate of climb is higher than that specied by the Climb threshold the LIVE SD creates a beeping
sound. The rate (cadence) of the beeps increases as the climb rate increases. This increase in rate is
not linear. The cadence parameter species which cadence curve should be used. Current there are 2
possibilities represented in the graph of Figure 4.27.
Figure 4.27: Cadence timing
Dynamic Frequency
The LIVE SD beeps at a specied pitch (frequency) when a certain rate of climb is encountered. When
dynamic frequency is o, the pitch (frequency) of that beep will remain constant if the rate of climb
changes. With dynamic frequency on, the pitch of the beep may vary if the rate of climb varies during
the individual beep.
Buzzer
Is so called because of the sound it emits, which resembles a buzzing sound.
The buzzer sound is produced when the rate of climb is close to, but has not yet reached the specied
Climb threshold (see 13.3.1). This value is set between 0 and 9 with each unit corresponding to be 0.1 m/s,
ie. 3 is 0.3m/s. Subtracting this decimal value from the climb threshold will give us the value at which
41
Page 43
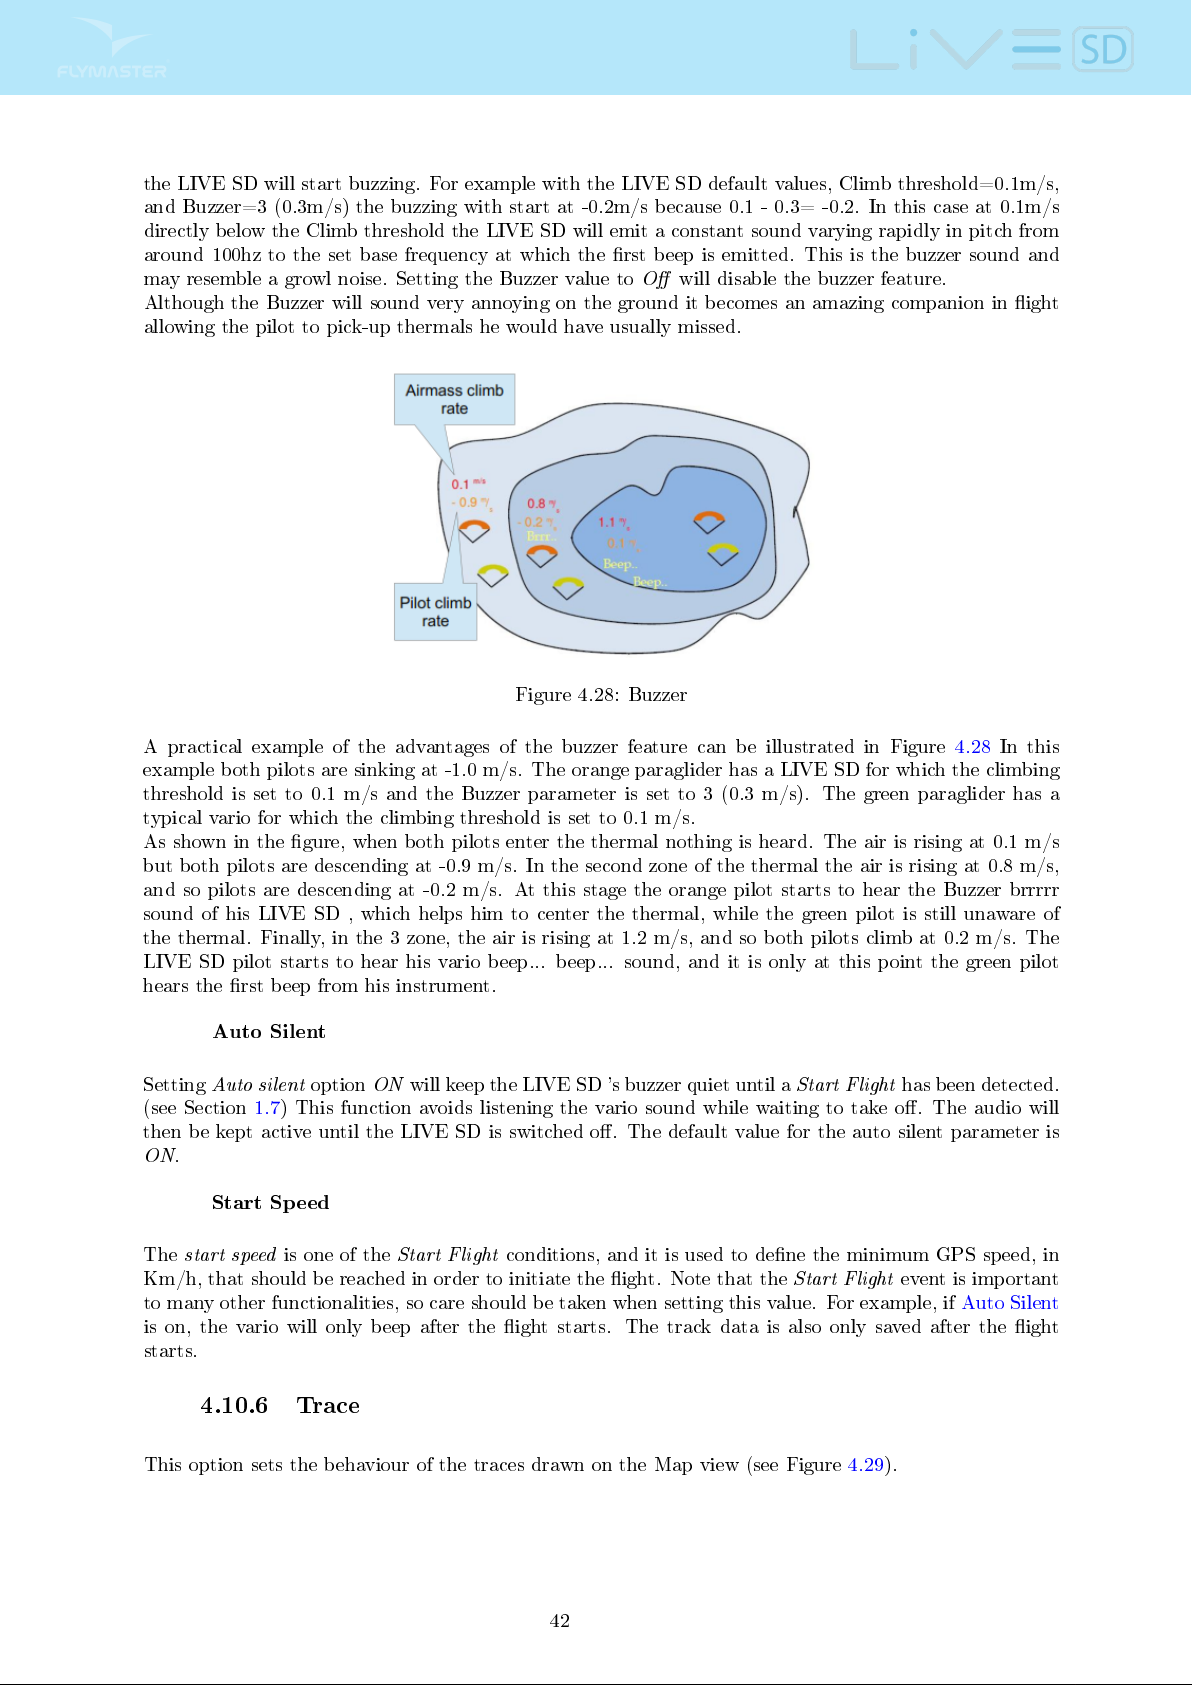
the LIVE SD will start buzzing. For example with the LIVE SD default values, Climb threshold=0.1m/s,
and Buzzer=3 (0.3m/s) the buzzing with start at -0.2m/s because 0.1 - 0.3= -0.2. In this case at 0.1m/s
directly below the Climb threshold the LIVE SD will emit a constant sound varying rapidly in pitch from
around 100hz to the set base frequency at which the rst beep is emitted. This is the buzzer sound and
may resemble a growl noise. Setting the Buzzer value to
Although the Buzzer will sound very annoying on the ground it becomes an amazing companion in ight
allowing the pilot to pick-up thermals he would have usually missed.
Figure 4.28: Buzzer
A practical example of the advantages of the buzzer feature can be illustrated in Figure 4.28 In this
example both pilots are sinking at -1.0 m/s. The orange paraglider has a LIVE SD for which the climbing
threshold is set to 0.1 m/s and the Buzzer parameter is set to 3 (0.3 m/s). The green paraglider has a
typical vario for which the climbing threshold is set to 0.1 m/s.
As shown in the gure, when both pilots enter the thermal nothing is heard. The air is rising at 0.1 m/s
but both pilots are descending at -0.9 m/s. In the second zone of the thermal the air is rising at 0.8 m/s,
and so pilots are descending at -0.2 m/s. At this stage the orange pilot starts to hear the Buzzer brrrrr
sound of his LIVE SD , which helps him to center the thermal, while the green pilot is still unaware of
the thermal. Finally, in the 3 zone, the air is rising at 1.2 m/s, and so both pilots climb at 0.2 m/s. The
LIVE SD pilot starts to hear his vario beep... beep... sound, and it is only at this point the green pilot
hears the rst beep from his instrument.
O
will disable the buzzer feature.
Auto Silent
Setting
(see Section 1.7) This function avoids listening the vario sound while waiting to take o. The audio will
then be kept active until the LIVE SD is switched o. The default value for the auto silent parameter is
ON
The
Km/h, that should be reached in order to initiate the ight. Note that the
to many other functionalities, so care should be taken when setting this value. For example, if Auto Silent
is on, the vario will only beep after the ight starts. The track data is also only saved after the ight
starts.
Auto silent
.
Start Speed
start speed
option
is one of the
ON
will keep the LIVE SD 's buzzer quiet until a
Start Flight
conditions, and it is used to dene the minimum GPS speed, in
Start Flight
Start Flight
has been detected.
event is important
4.10.6 Trace
This option sets the behaviour of the traces drawn on the Map view (see Figure 4.29).
42
Page 44
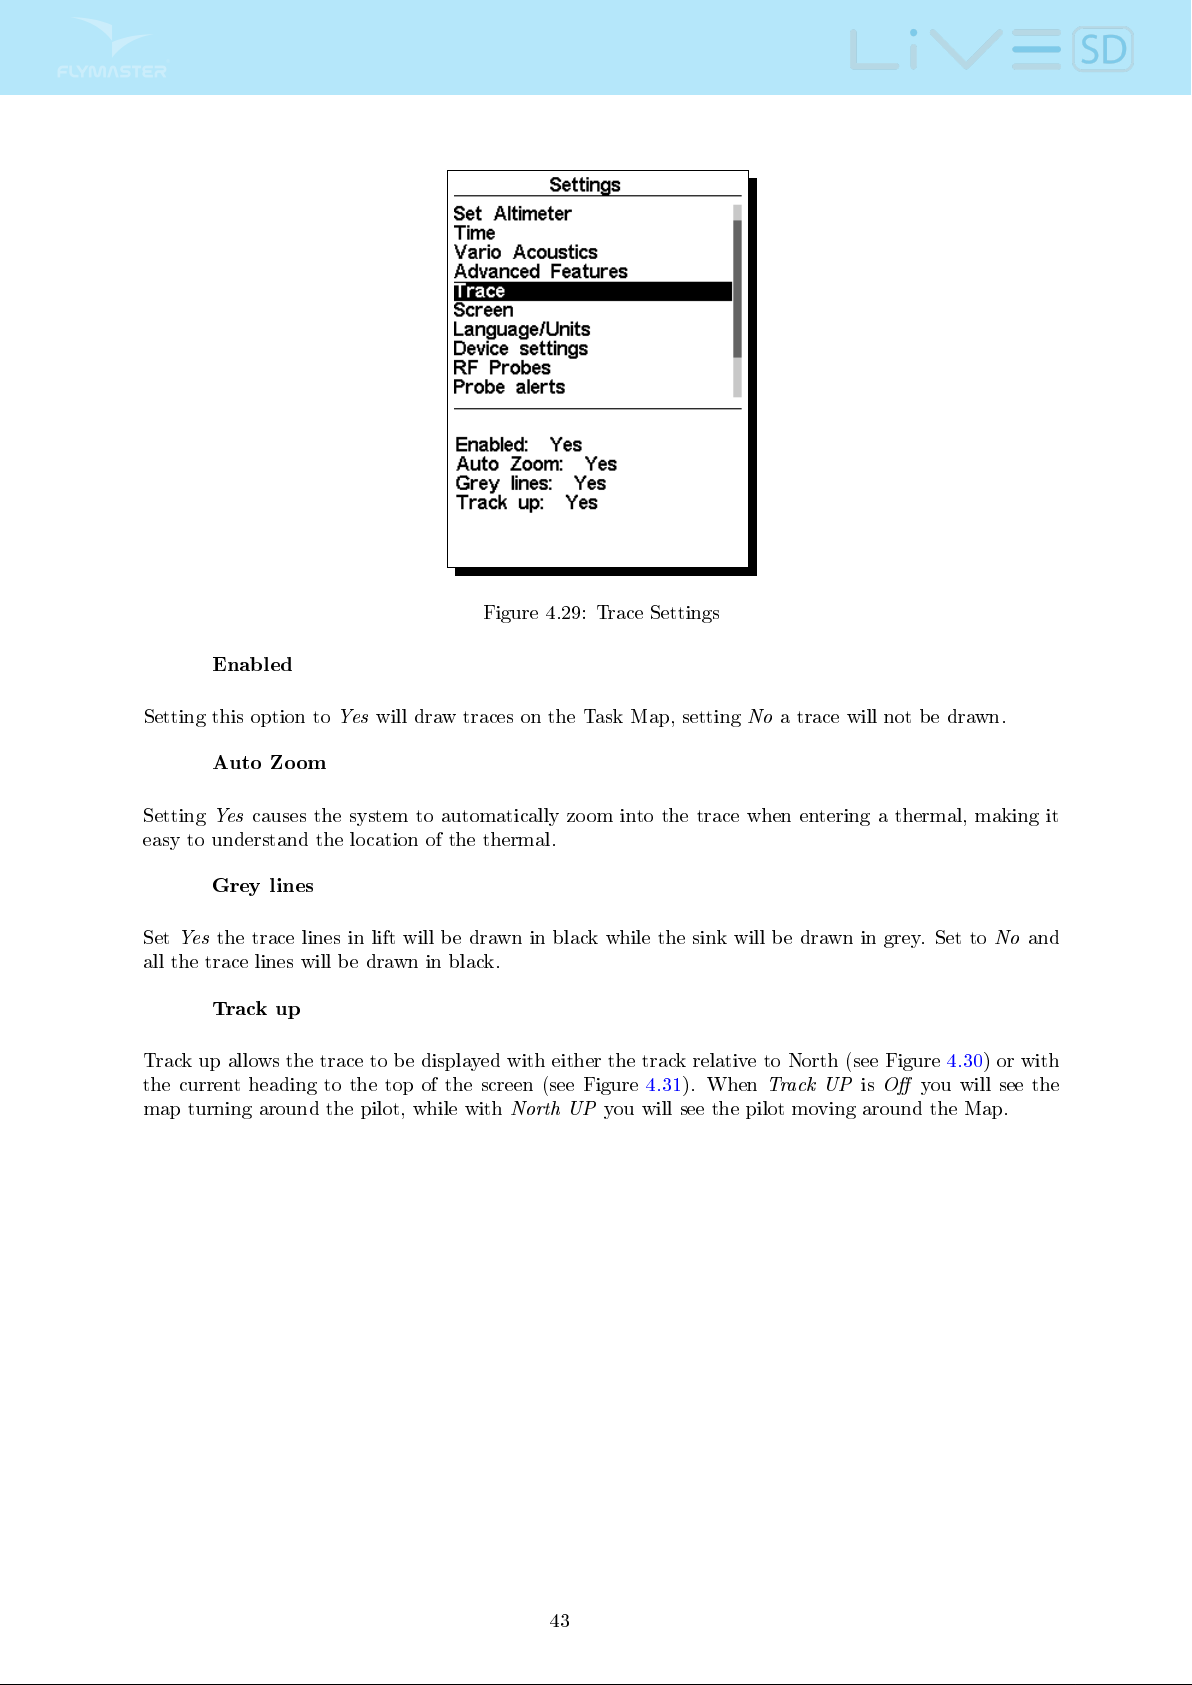
Enabled
Figure 4.29: Trace Settings
Setting this option to
Yes
will draw traces on the Task Map, setting
No
a trace will not be drawn.
Auto Zoom
Setting
Yes
causes the system to automatically zoom into the trace when entering a thermal, making it
easy to understand the location of the thermal.
Grey lines
Set
Yes
the trace lines in lift will be drawn in black while the sink will be drawn in grey. Set toNoand
all the trace lines will be drawn in black.
Track up
Track up allows the trace to be displayed with either the track relative to North (see Figure 4.30) or with
the current heading to the top of the screen (see Figure 4.31). When
map turning around the pilot, while with
North UP
you will see the pilot moving around the Map.
Track UPisO
you will see the
43
Page 45
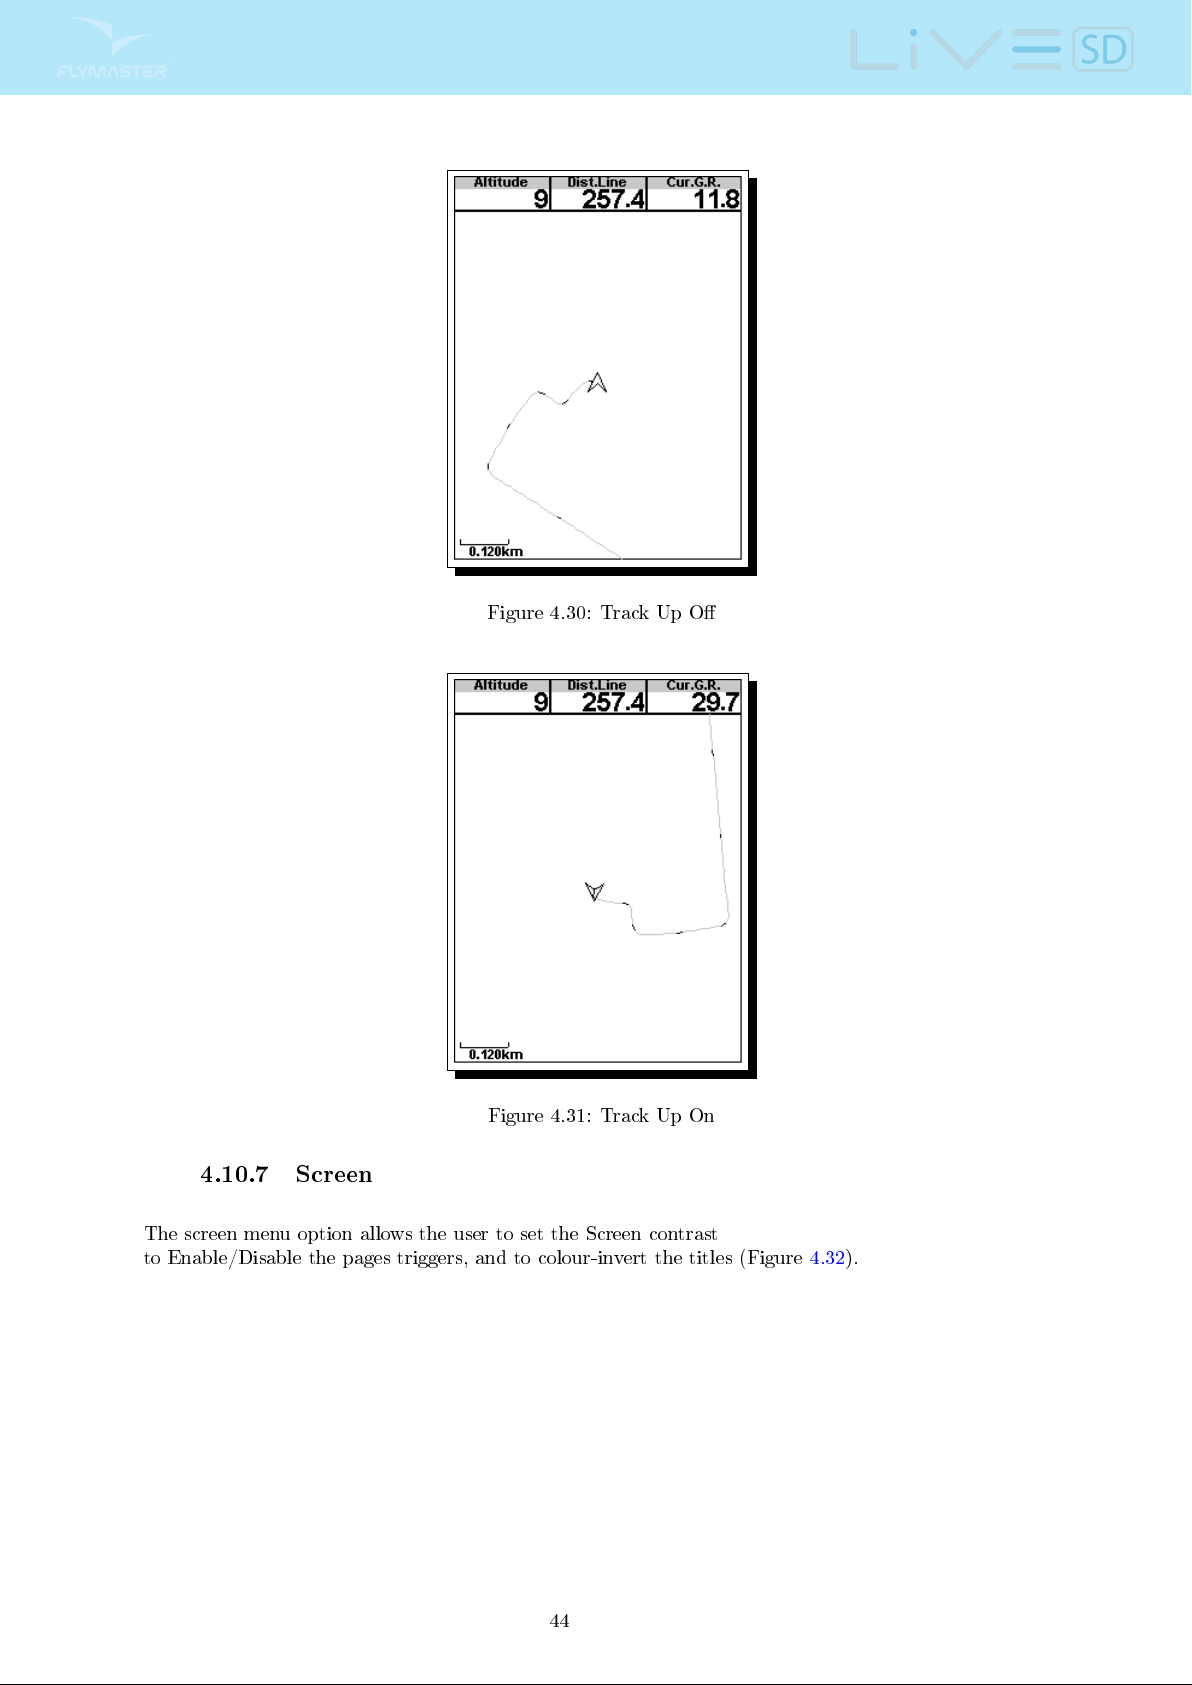
4.10.7 Screen
Figure 4.30: Track Up O
Figure 4.31: Track Up On
The screen menu option allows the user to set the Screen contrast
to Enable/Disable the pages triggers, and to colour-invert the titles (Figure 4.32).
44
Page 46
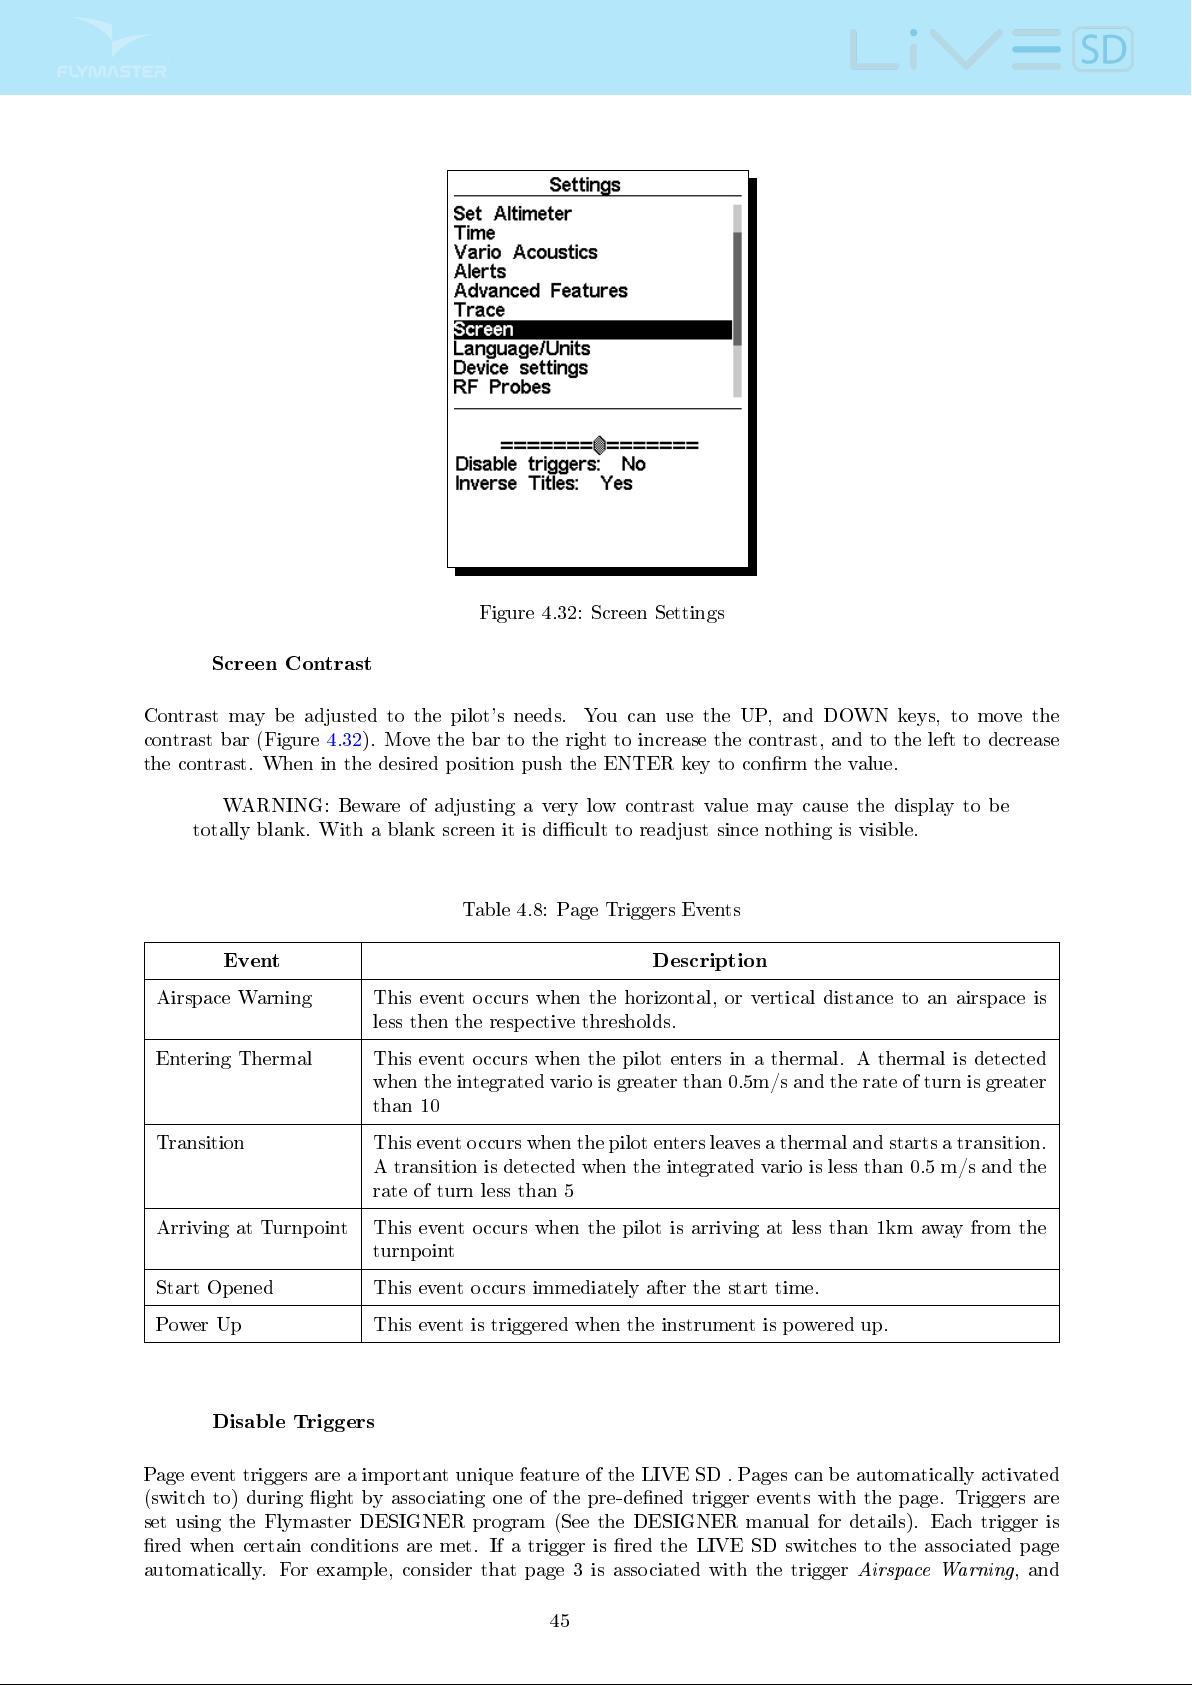
Figure 4.32: Screen Settings
Screen Contrast
Contrast may be adjusted to the pilot's needs. You can use the UP, and DOWN keys, to move the
contrast bar (Figure 4.32). Move the bar to the right to increase the contrast, and to the left to decrease
the contrast. When in the desired position push the ENTER key to conrm the value.
WARNING: Beware of adjusting a very low contrast value may cause the display to be
totally blank. With a blank screen it is dicult to readjust since nothing is visible.
Table 4.8: Page Triggers Events
Event Description
Airspace Warning This event occurs when the horizontal, or vertical distance to an airspace is
less then the respective thresholds.
Entering Thermal This event occurs when the pilot enters in a thermal. A thermal is detected
when the integrated vario is greater than 0.5m/s and the rate of turn is greater
than 10
Transition This event occurs when the pilot enters leaves a thermal and starts a transition.
A transition is detected when the integrated vario is less than 0.5 m/s and the
rate of turn less than 5
Arriving at Turnpoint This event occurs when the pilot is arriving at less than 1km away from the
turnpoint
Start Opened This event occurs immediately after the start time.
Power Up This event is triggered when the instrument is powered up.
Disable Triggers
Page event triggers are a important unique feature of the LIVE SD . Pages can be automatically activated
(switch to) during ight by associating one of the pre-dened trigger events with the page. Triggers are
set using the Flymaster DESIGNER program (See the DESIGNER manual for details). Each trigger is
red when certain conditions are met. If a trigger is red the LIVE SD switches to the associated page
automatically. For example, consider that page 3 is associated with the trigger
Airspace Warning
, and
45
Page 47
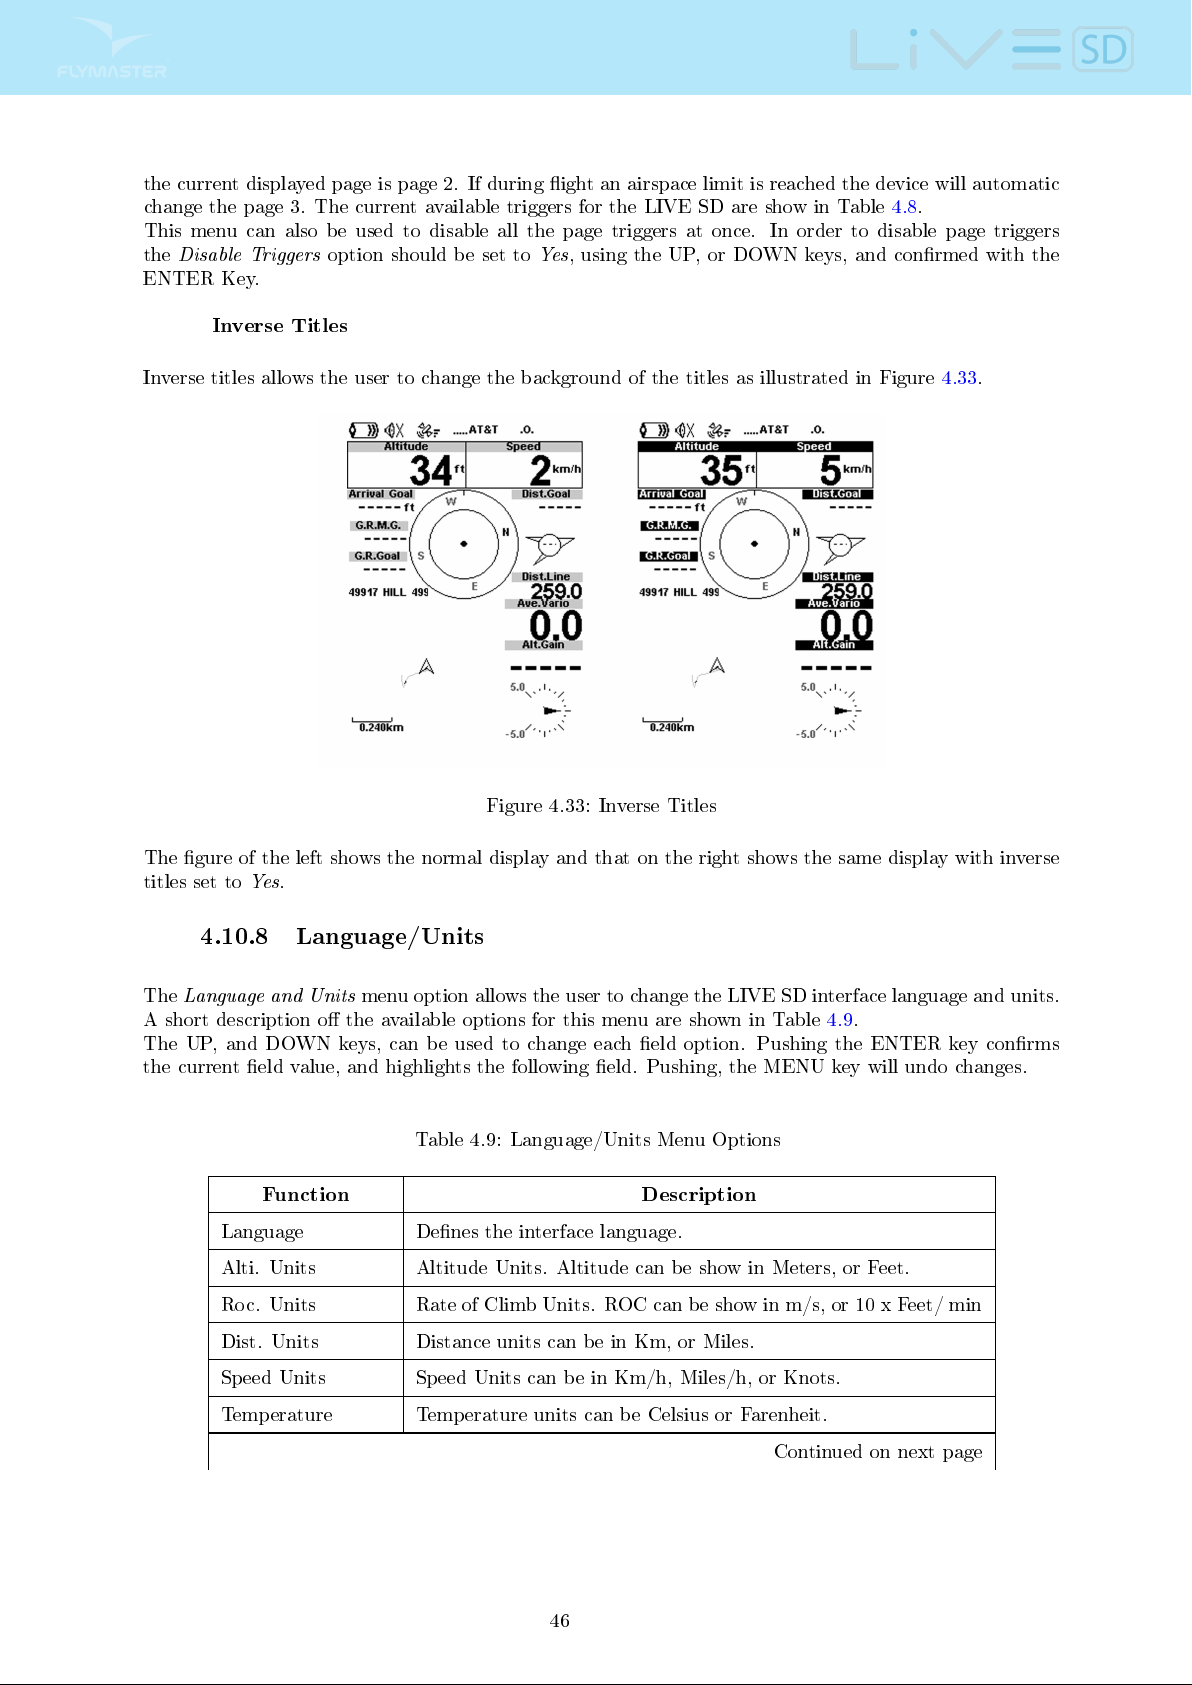
the current displayed page is page 2. If during ight an airspace limit is reached the device will automatic
change the page 3. The current available triggers for the LIVE SD are show in Table 4.8.
This menu can also be used to disable all the page triggers at once. In order to disable page triggers
the
Disable Triggers
ENTER Key.
Inverse Titles
Inverse titles allows the user to change the background of the titles as illustrated in Figure 4.33.
option should be set to
Yes
, using the UP, or DOWN keys, and conrmed with the
Figure 4.33: Inverse Titles
The gure of the left shows the normal display and that on the right shows the same display with inverse
titles set to
Yes
.
4.10.8 Language/Units
The
Language and Units
A short description o the available options for this menu are shown in Table 4.9.
The UP, and DOWN keys, can be used to change each eld option. Pushing the ENTER key conrms
the current eld value, and highlights the following eld. Pushing, the MENU key will undo changes.
Function Description
Language Denes the interface language.
Alti. Units Altitude Units. Altitude can be show in Meters, or Feet.
Roc. Units Rate of Climb Units. ROC can be show in m/s, or 10 x Feet/ min
Dist. Units Distance units can be in Km, or Miles.
Speed Units Speed Units can be in Km/h, Miles/h, or Knots.
menu option allows the user to change the LIVE SD interface language and units.
Table 4.9: Language/Units Menu Options
Temperature Temperature units can be Celsius or Farenheit.
Continued on next page
46
Page 48
Table 4.9 continued from previous page
Field ID Description
Coords. Coordinates format. These can be either:
DD°MM'SS?
DD°MM.mmm'
DD.dddd
UTM
4.10.9 Device Settings
This menu option allows the user to execute some recovery functions. A short description of the available
options is shown in Table 4.10.
Table 4.10: Device Settings
Function Description
Factory Settings Reset all parameters to the default factory values. This will not
change the layout to the factory default layout. Care should be
taken because all changes made by the user are lost.
Reset now Makes a hardware reset to the instrument. The result is the same
as the one presented in Section 1.5.
Auto-o If set to
5 km/h, and integrated vario less than +-1.5 m/s, for more than
30 seconds.
Yes
the LIVE SD turns o if the GPS speed is less than
4.10.10 RF Probes
The
RF Probes
M1 and Heart-G to the LIVE SD . Pairing is performed automatically. When ENTER is pressed the LIVE
SD will look to see what wireless devices are around and it will shows these on the screen (see Figure 4.34).
Devices are identied by their name (e.g. M1, TAS) and serial number. Devices can be selected using the
UP, or DOWN keys. For the selected (highlighted) device the pairing state is shown on the bottom of
the screen. To pair a device the state should be changed from
always automatically connect with the wireless device. The LIVE SD can be paired with several devices.
menu option allows the user to pair up any of the Flymaster wireless devices including the
NotoYes
. Once paired the LIVE SD will
47
Page 49
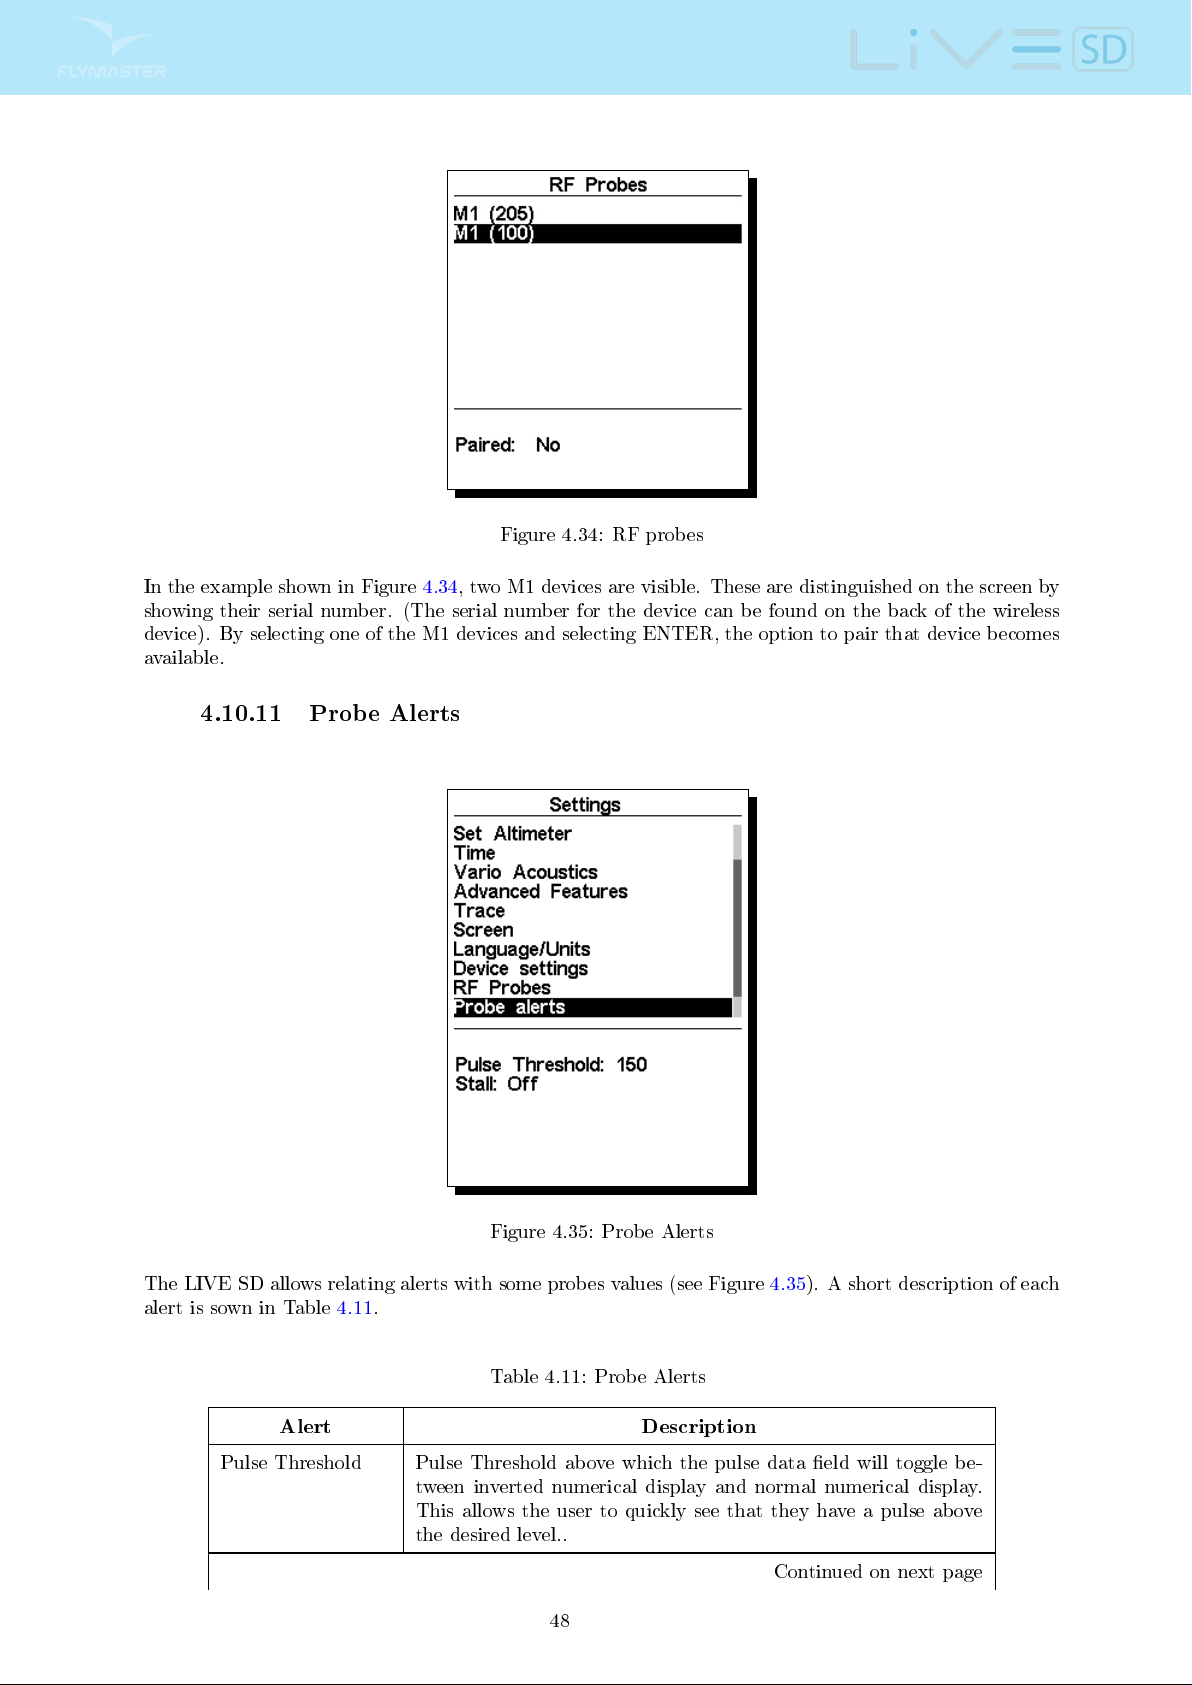
Figure 4.34: RF probes
In the example shown in Figure 4.34, two M1 devices are visible. These are distinguished on the screen by
showing their serial number. (The serial number for the device can be found on the back of the wireless
device). By selecting one of the M1 devices and selecting ENTER, the option to pair that device becomes
available.
4.10.11 Probe Alerts
Figure 4.35: Probe Alerts
The LIVE SD allows relating alerts with some probes values (see Figure 4.35). A short description of each
alert is sown in Table 4.11.
Table 4.11: Probe Alerts
Alert Description
Pulse Threshold Pulse Threshold above which the pulse data eld will toggle be-
tween inverted numerical display and normal numerical display.
This allows the user to quickly see that they have a pulse above
the desired level..
Continued on next page
48
Page 50
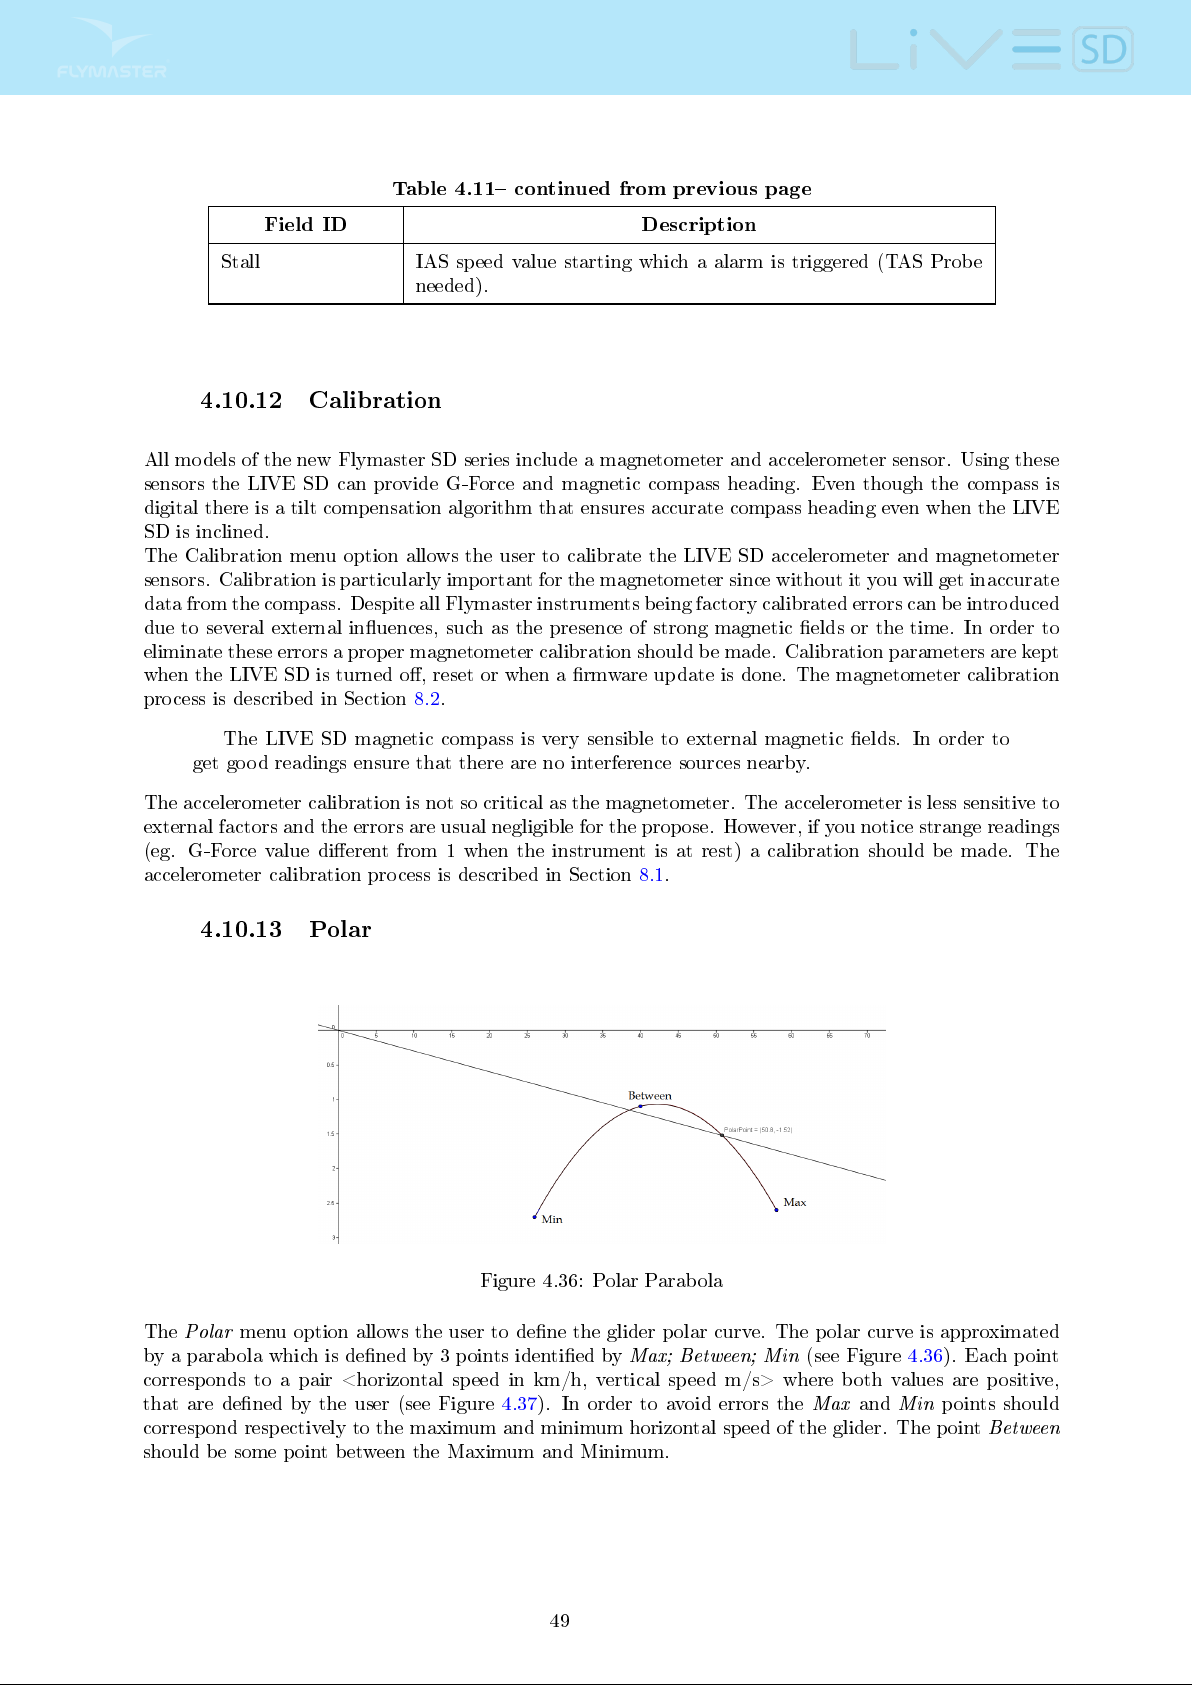
Table 4.11 continued from previous page
Field ID Description
Stall IAS speed value starting which a alarm is triggered (TAS Probe
needed).
4.10.12 Calibration
All models of the new Flymaster SD series include a magnetometer and accelerometer sensor. Using these
sensors the LIVE SD can provide G-Force and magnetic compass heading. Even though the compass is
digital there is a tilt compensation algorithm that ensures accurate compass heading even when the LIVE
SD is inclined.
The Calibration menu option allows the user to calibrate the LIVE SD accelerometer and magnetometer
sensors. Calibration is particularly important for the magnetometer since without it you will get inaccurate
data from the compass. Despite all Flymaster instruments being factory calibrated errors can be introduced
due to several external inuences, such as the presence of strong magnetic elds or the time. In order to
eliminate these errors a proper magnetometer calibration should be made. Calibration parameters are kept
when the LIVE SD is turned o, reset or when a rmware update is done. The magnetometer calibration
process is described in Section 8.2.
The LIVE SD magnetic compass is very sensible to external magnetic elds. In order to
get good readings ensure that there are no interference sources nearby.
The accelerometer calibration is not so critical as the magnetometer. The accelerometer is less sensitive to
external factors and the errors are usual negligible for the propose. However, if you notice strange readings
(eg. G-Force value dierent from 1 when the instrument is at rest) a calibration should be made. The
accelerometer calibration process is described in Section 8.1.
4.10.13 Polar
Figure 4.36: Polar Parabola
The
Polar
menu option allows the user to dene the glider polar curve. The polar curve is approximated
by a parabola which is dened by 3 points identied by
corresponds to a pair <horizontal speed in km/h, vertical speed m/s> where both values are positive,
that are dened by the user (see Figure 4.37). In order to avoid errors the
correspond respectively to the maximum and minimum horizontal speed of the glider. The point
should be some point between the Maximum and Minimum.
Max; Between; Min
(see Figure 4.36). Each point
Max
and
Min
points should
Between
49
Page 51
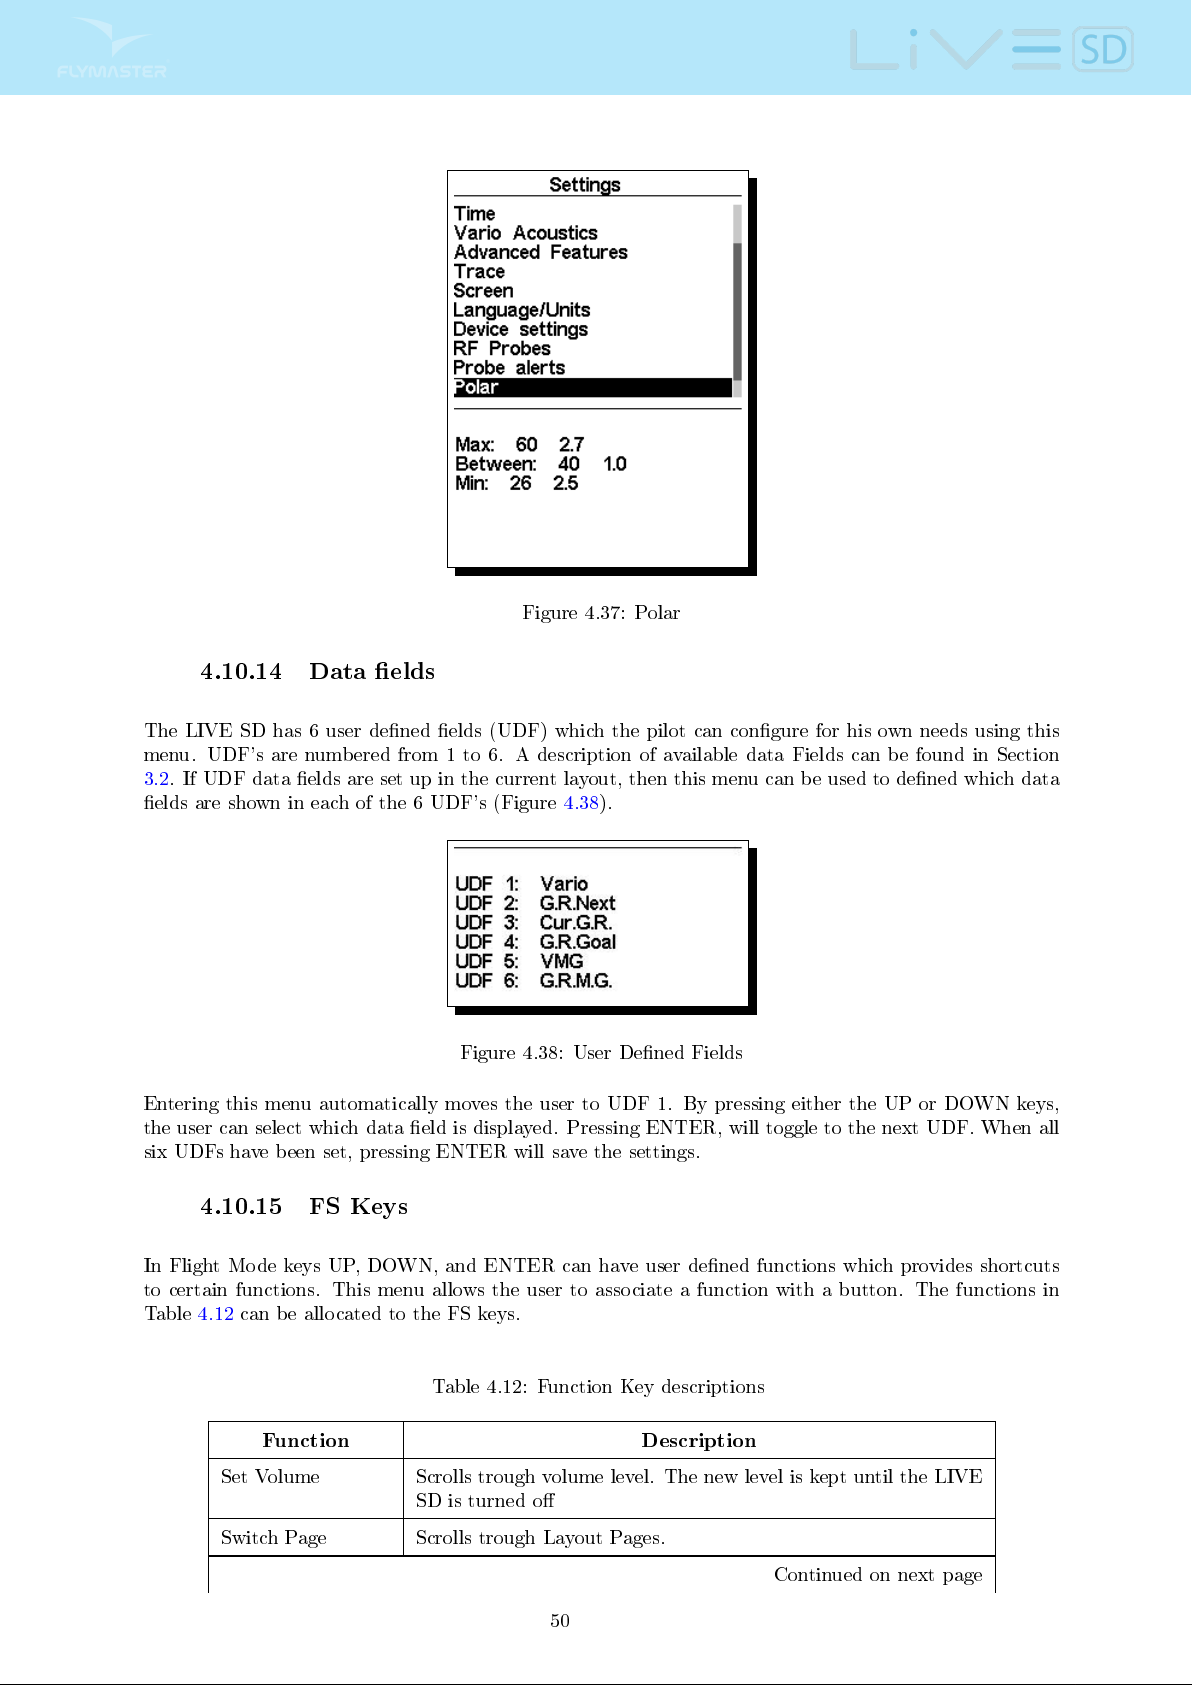
Figure 4.37: Polar
4.10.14 Data elds
The LIVE SD has 6 user dened elds (UDF) which the pilot can congure for his own needs using this
menu. UDF's are numbered from 1 to 6. A description of available data Fields can be found in Section
3.2. If UDF data elds are set up in the current layout, then this menu can be used to dened which data
elds are shown in each of the 6 UDF's (Figure 4.38).
Figure 4.38: User Dened Fields
Entering this menu automatically moves the user to UDF 1. By pressing either the UP or DOWN keys,
the user can select which data eld is displayed. Pressing ENTER, will toggle to the next UDF. When all
six UDFs have been set, pressing ENTER will save the settings.
4.10.15 FS Keys
In Flight Mode keys UP, DOWN, and ENTER can have user dened functions which provides shortcuts
to certain functions. This menu allows the user to associate a function with a button. The functions in
Table 4.12 can be allocated to the FS keys.
Table 4.12: Function Key descriptions
Function Description
Set Volume Scrolls trough volume level. The new level is kept until the LIVE
SD is turned o
Switch Page Scrolls trough Layout Pages.
Continued on next page
50
Page 52
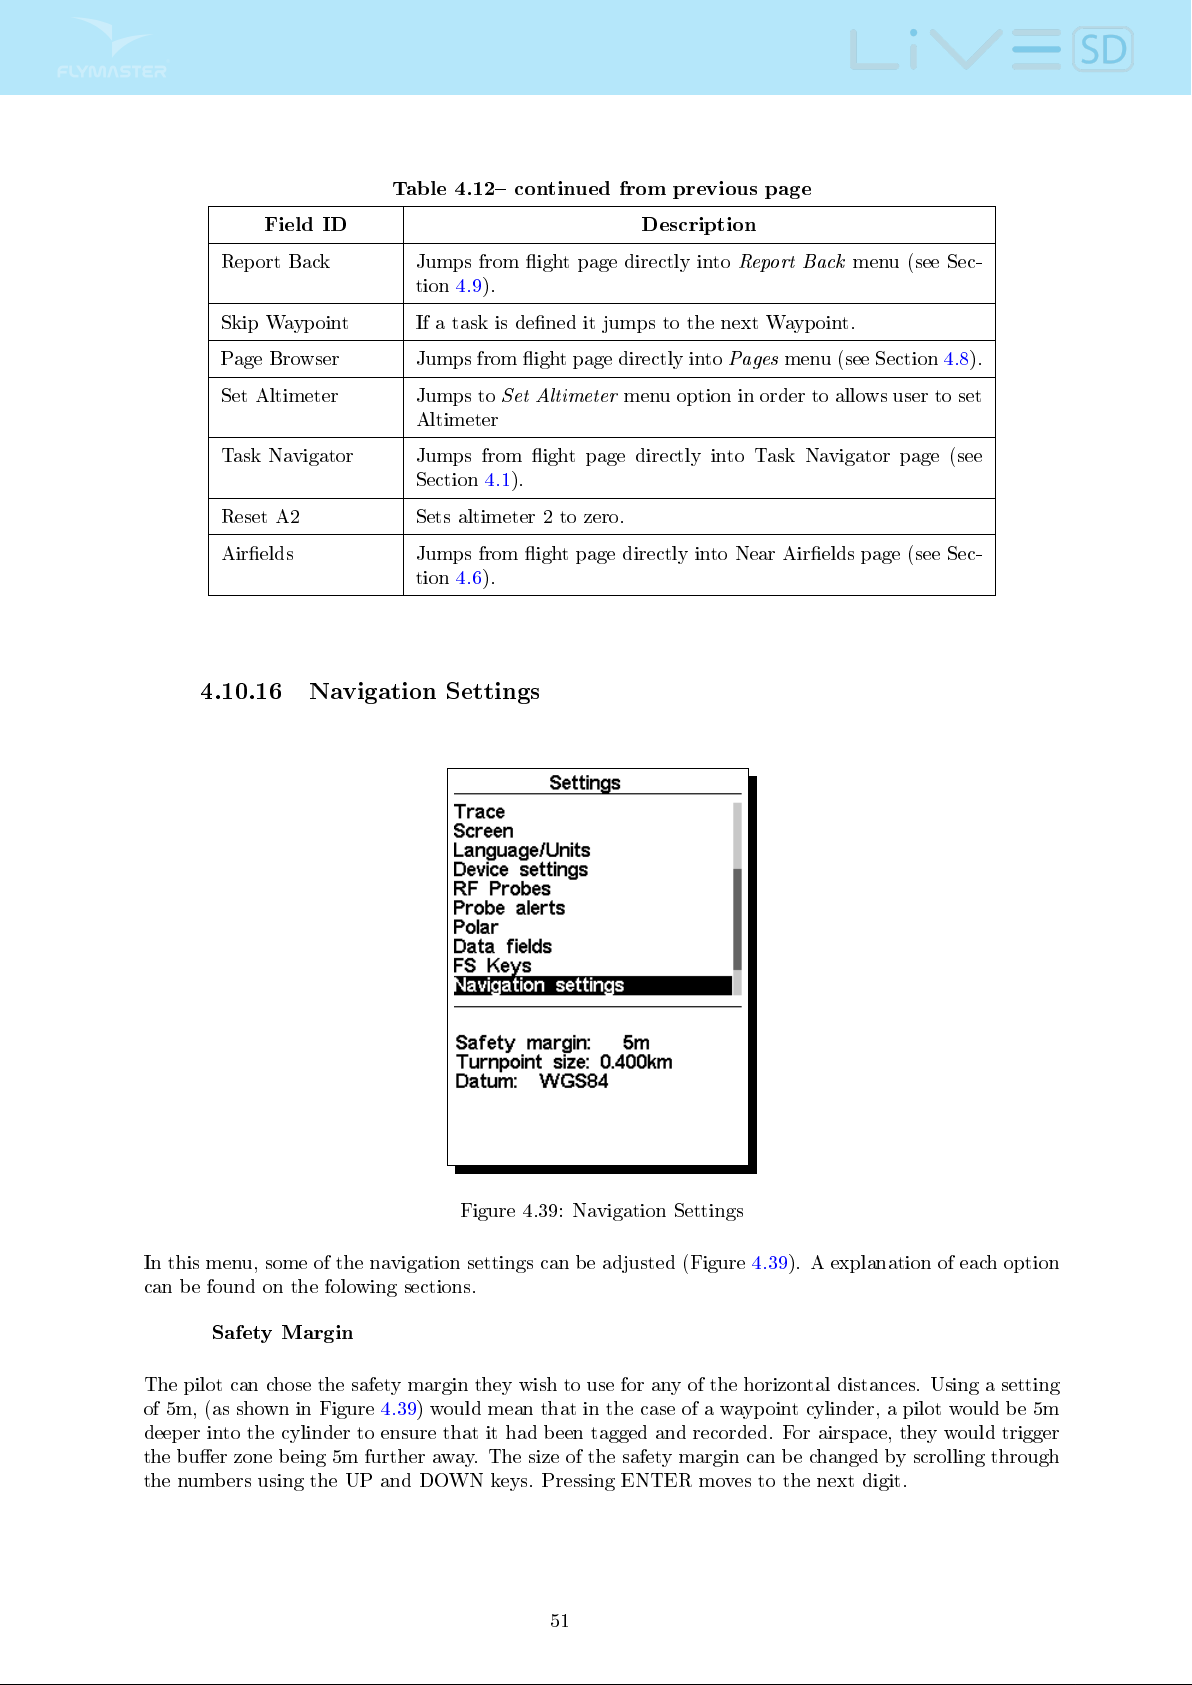
Table 4.12 continued from previous page
Field ID Description
Report Back Jumps from ight page directly into
tion 4.9).
Skip Waypoint If a task is dened it jumps to the next Waypoint.
Page Browser Jumps from ight page directly into
Set Altimeter Jumps to
Altimeter
Task Navigator Jumps from ight page directly into Task Navigator page (see
Section 4.1).
Reset A2 Sets altimeter 2 to zero.
Airelds Jumps from ight page directly into Near Airelds page (see Sec-
tion 4.6).
Set Altimeter
menu option in order to allows user to set
Report Back
Pages
menu (see Section 4.8).
menu (see Sec-
4.10.16 Navigation Settings
Figure 4.39: Navigation Settings
In this menu, some of the navigation settings can be adjusted (Figure 4.39). A explanation of each option
can be found on the folowing sections.
Safety Margin
The pilot can chose the safety margin they wish to use for any of the horizontal distances. Using a setting
of 5m, (as shown in Figure 4.39) would mean that in the case of a waypoint cylinder, a pilot would be 5m
deeper into the cylinder to ensure that it had been tagged and recorded. For airspace, they would trigger
the buer zone being 5m further away. The size of the safety margin can be changed by scrolling through
the numbers using the UP and DOWN keys. Pressing ENTER moves to the next digit.
51
Page 53
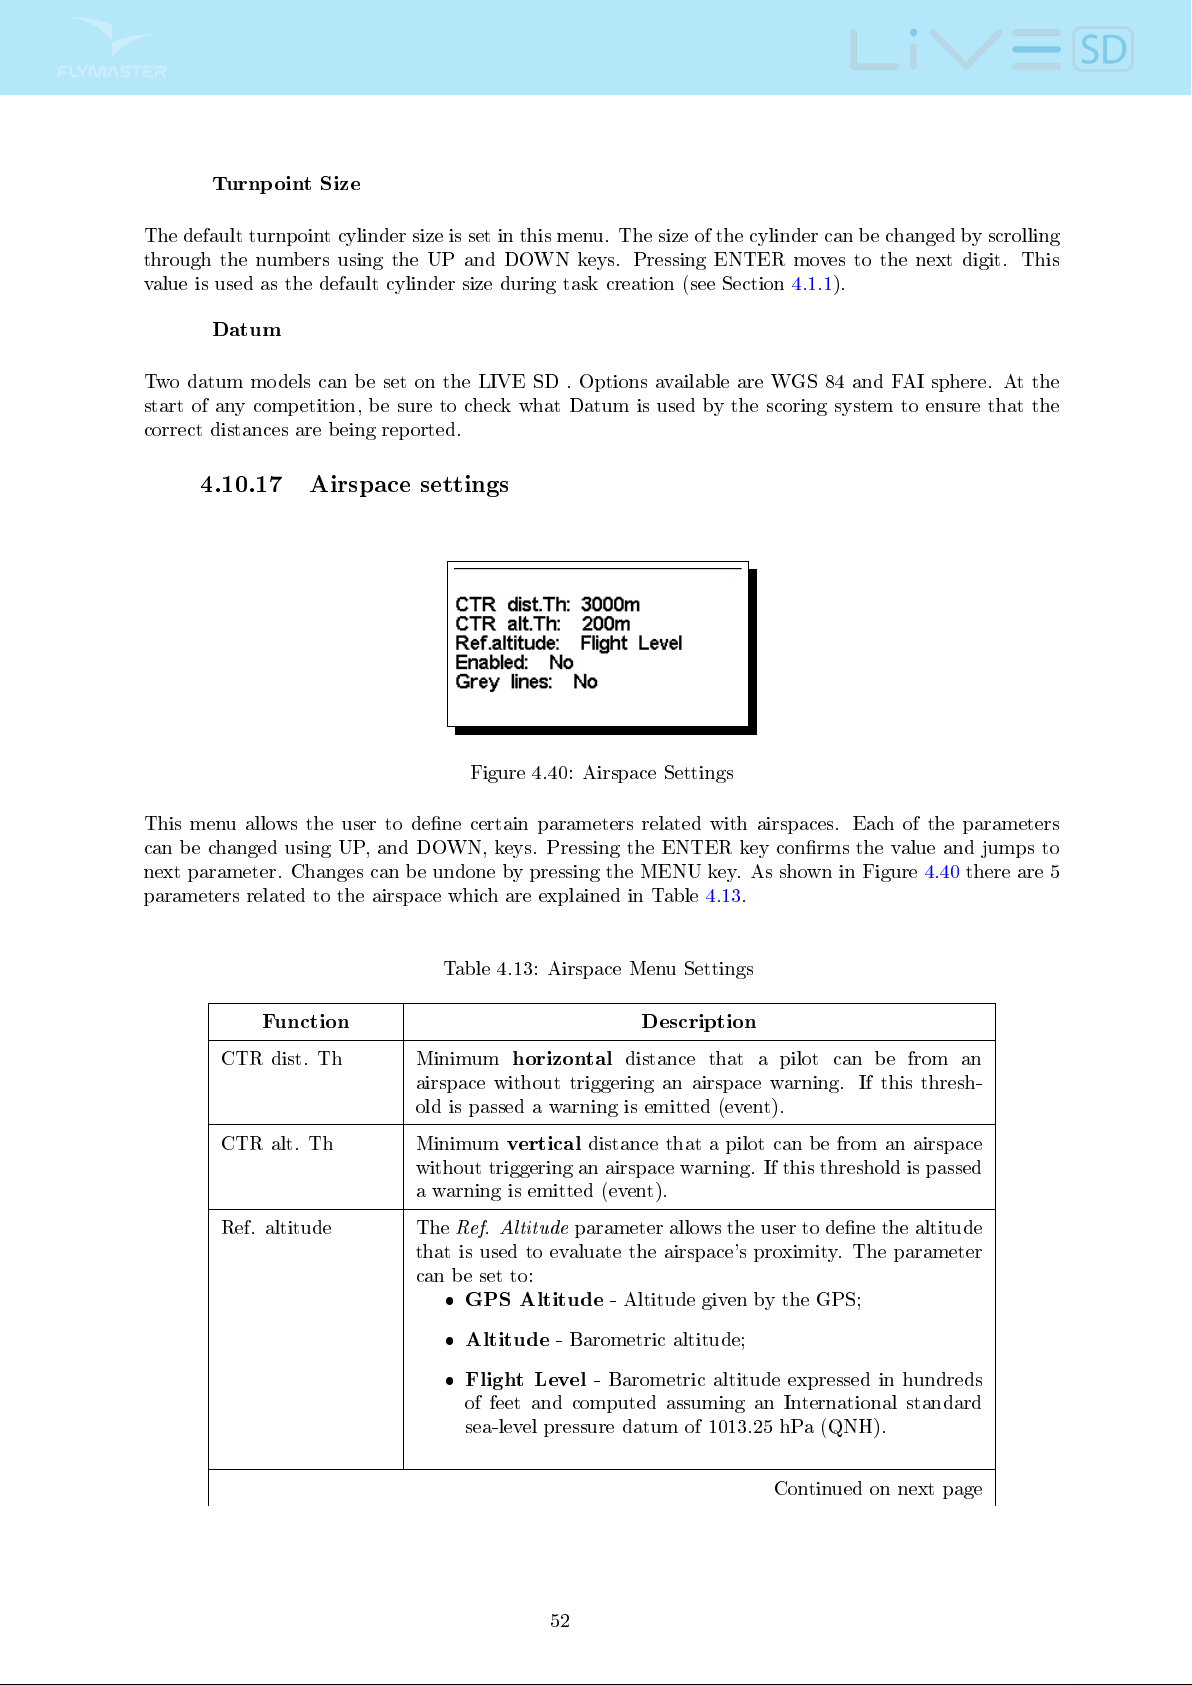
Turnpoint Size
The default turnpoint cylinder size is set in this menu. The size of the cylinder can be changed by scrolling
through the numbers using the UP and DOWN keys. Pressing ENTER moves to the next digit. This
value is used as the default cylinder size during task creation (see Section 4.1.1).
Datum
Two datum models can be set on the LIVE SD . Options available are WGS 84 and FAI sphere. At the
start of any competition, be sure to check what Datum is used by the scoring system to ensure that the
correct distances are being reported.
4.10.17 Airspace settings
Figure 4.40: Airspace Settings
This menu allows the user to dene certain parameters related with airspaces. Each of the parameters
can be changed using UP, and DOWN, keys. Pressing the ENTER key conrms the value and jumps to
next parameter. Changes can be undone by pressing the MENU key. As shown in Figure 4.40 there are 5
parameters related to the airspace which are explained in Table 4.13.
Table 4.13: Airspace Menu Settings
Function Description
CTR dist. Th Minimum
airspace without triggering an airspace warning. If this thresh-
old is passed a warning is emitted (event).
CTR alt. Th Minimum
without triggering an airspace warning. If this threshold is passed
a warning is emitted (event).
Ref. altitude The
that is used to evaluate the airspace's proximity. The parameter
can be set to:
horizontal
vertical
Ref. Altitude
GPS Altitude
Altitude
- Barometric altitude;
distance that a pilot can be from an
distance that a pilot can be from an airspace
parameter allows the user to dene the altitude
- Altitude given by the GPS;
Flight Level
of feet and computed assuming an International standard
sea-level pressure datum of 1013.25 hPa (QNH).
- Barometric altitude expressed in hundreds
Continued on next page
52
Page 54
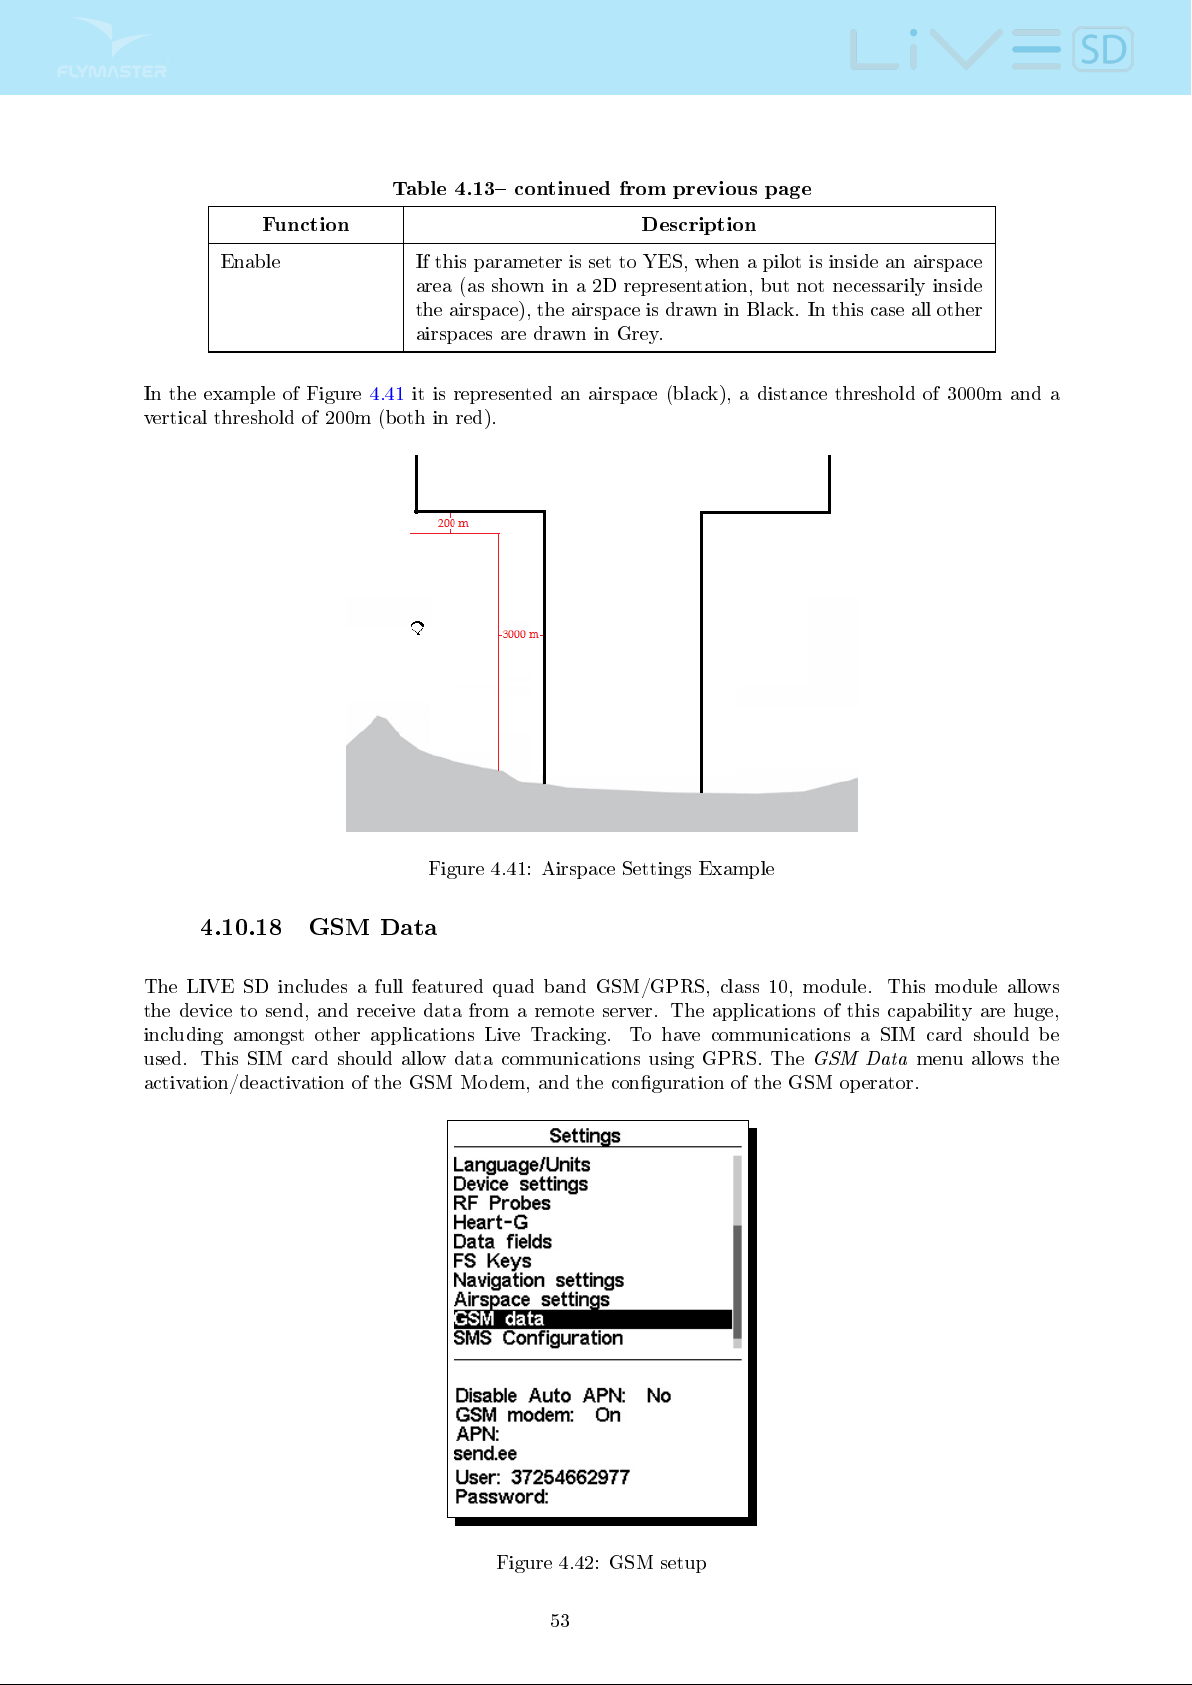
Table 4.13 continued from previous page
Function Description
Enable If this parameter is set to YES, when a pilot is inside an airspace
area (as shown in a 2D representation, but not necessarily inside
the airspace), the airspace is drawn in Black. In this case all other
airspaces are drawn in Grey.
In the example of Figure 4.41 it is represented an airspace (black), a distance threshold of 3000m and a
vertical threshold of 200m (both in red).
Figure 4.41: Airspace Settings Example
4.10.18 GSM Data
The LIVE SD includes a full featured quad band GSM/GPRS, class 10, module. This module allows
the device to send, and receive data from a remote server. The applications of this capability are huge,
including amongst other applications Live Tracking. To have communications a SIM card should be
used. This SIM card should allow data communications using GPRS. The
activation/deactivation of the GSM Modem, and the conguration of the GSM operator.
GSM Data
menu allows the
Figure 4.42: GSM setup
53
Page 55
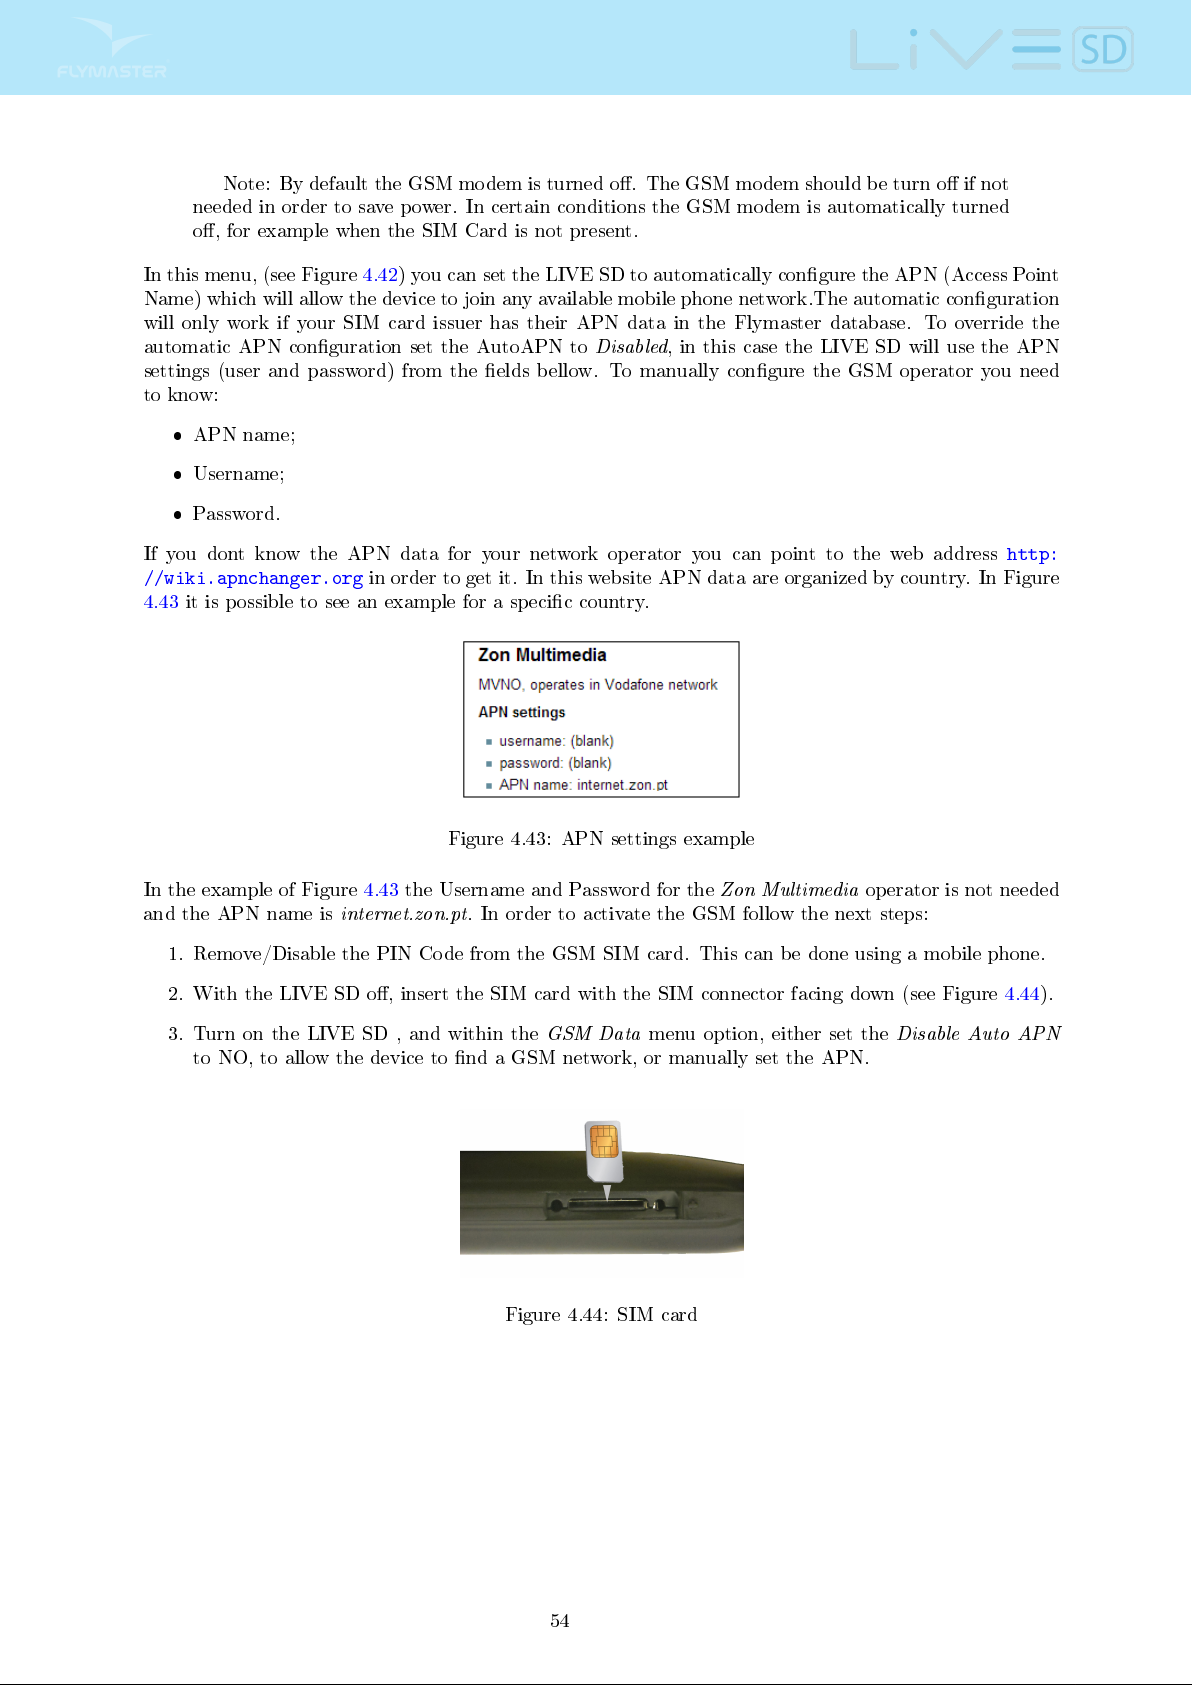
Note: By default the GSM modem is turned o. The GSM modem should be turn o if not
needed in order to save power. In certain conditions the GSM modem is automatically turned
o, for example when the SIM Card is not present.
In this menu, (see Figure 4.42) you can set the LIVE SD to automatically congure the APN (Access Point
Name) which will allow the device to join any available mobile phone network.The automatic conguration
will only work if your SIM card issuer has their APN data in the Flymaster database. To override the
automatic APN conguration set the AutoAPN to
Disabled
, in this case the LIVE SD will use the APN
settings (user and password) from the elds bellow. To manually congure the GSM operator you need
to know:
APN name;
Username;
Password.
If you dont know the APN data for your network operator you can point to the web address
//wiki.apnchanger.org
in order to get it. In this website APN data are organized by country. In Figure
4.43 it is possible to see an example for a specic country.
Figure 4.43: APN settings example
In the example of Figure 4.43 the Username and Password for the
and the APN name is
internet.zon.pt
. In order to activate the GSM follow the next steps:
Zon Multimedia
operator is not needed
1. Remove/Disable the PIN Code from the GSM SIM card. This can be done using a mobile phone.
2. With the LIVE SD o, insert the SIM card with the SIM connector facing down (see Figure 4.44).
3. Turn on the LIVE SD , and within the
GSM Data
menu option, either set the
Disable Auto APN
to NO, to allow the device to nd a GSM network, or manually set the APN.
http:
Figure 4.44: SIM card
54
Page 56
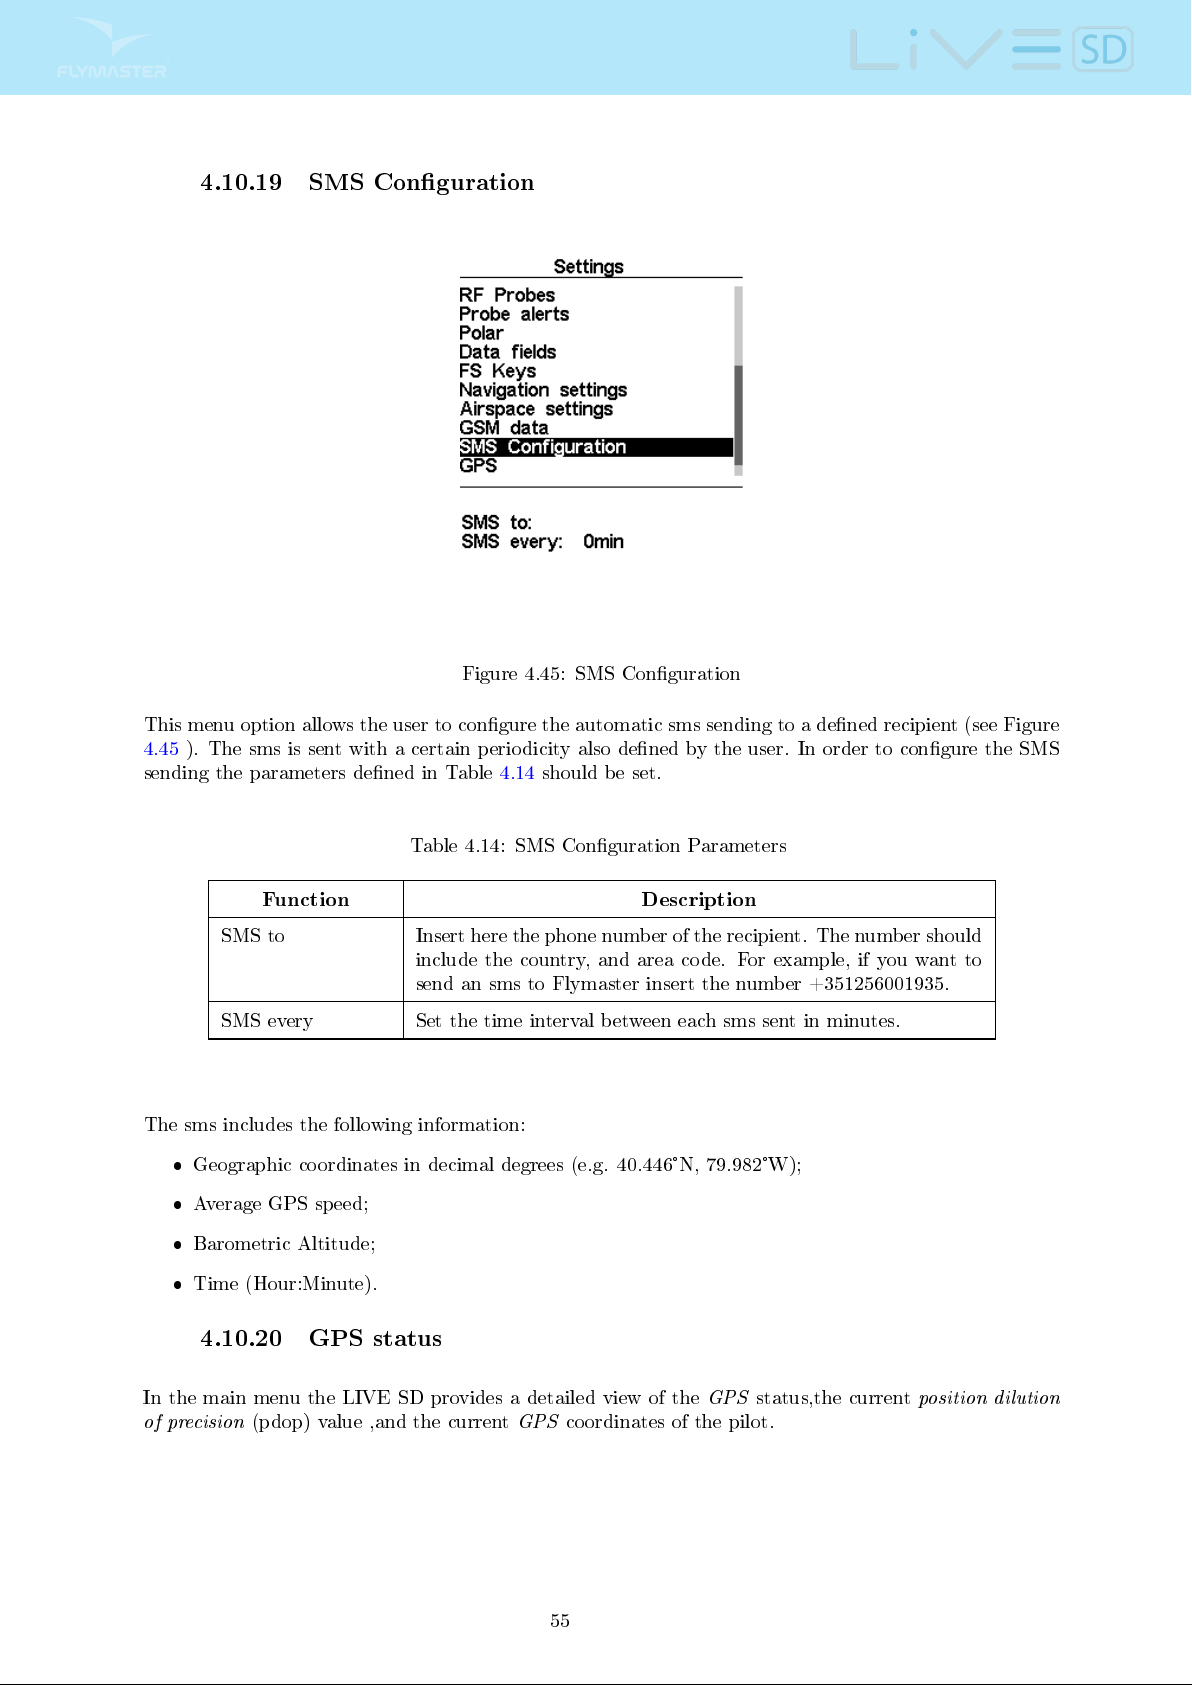
4.10.19 SMS Conguration
Figure 4.45: SMS Conguration
This menu option allows the user to congure the automatic sms sending to a dened recipient (see Figure
4.45 ). The sms is sent with a certain periodicity also dened by the user. In order to congure the SMS
sending the parameters dened in Table 4.14 should be set.
Table 4.14: SMS Conguration Parameters
Function Description
SMS to Insert here the phone number of the recipient. The number should
include the country, and area code. For example, if you want to
send an sms to Flymaster insert the number +351256001935.
SMS every Set the time interval between each sms sent in minutes.
The sms includes the following information:
Geographic coordinates in decimal degrees (e.g. 40.446°N, 79.982°W);
Average GPS speed;
Barometric Altitude;
Time (Hour:Minute).
4.10.20 GPS status
In the main menu the LIVE SD provides a detailed view of the
of precision
(pdop) value ,and the current
GPS
coordinates of the pilot.
GPS
status,the current
position dilution
55
Page 57
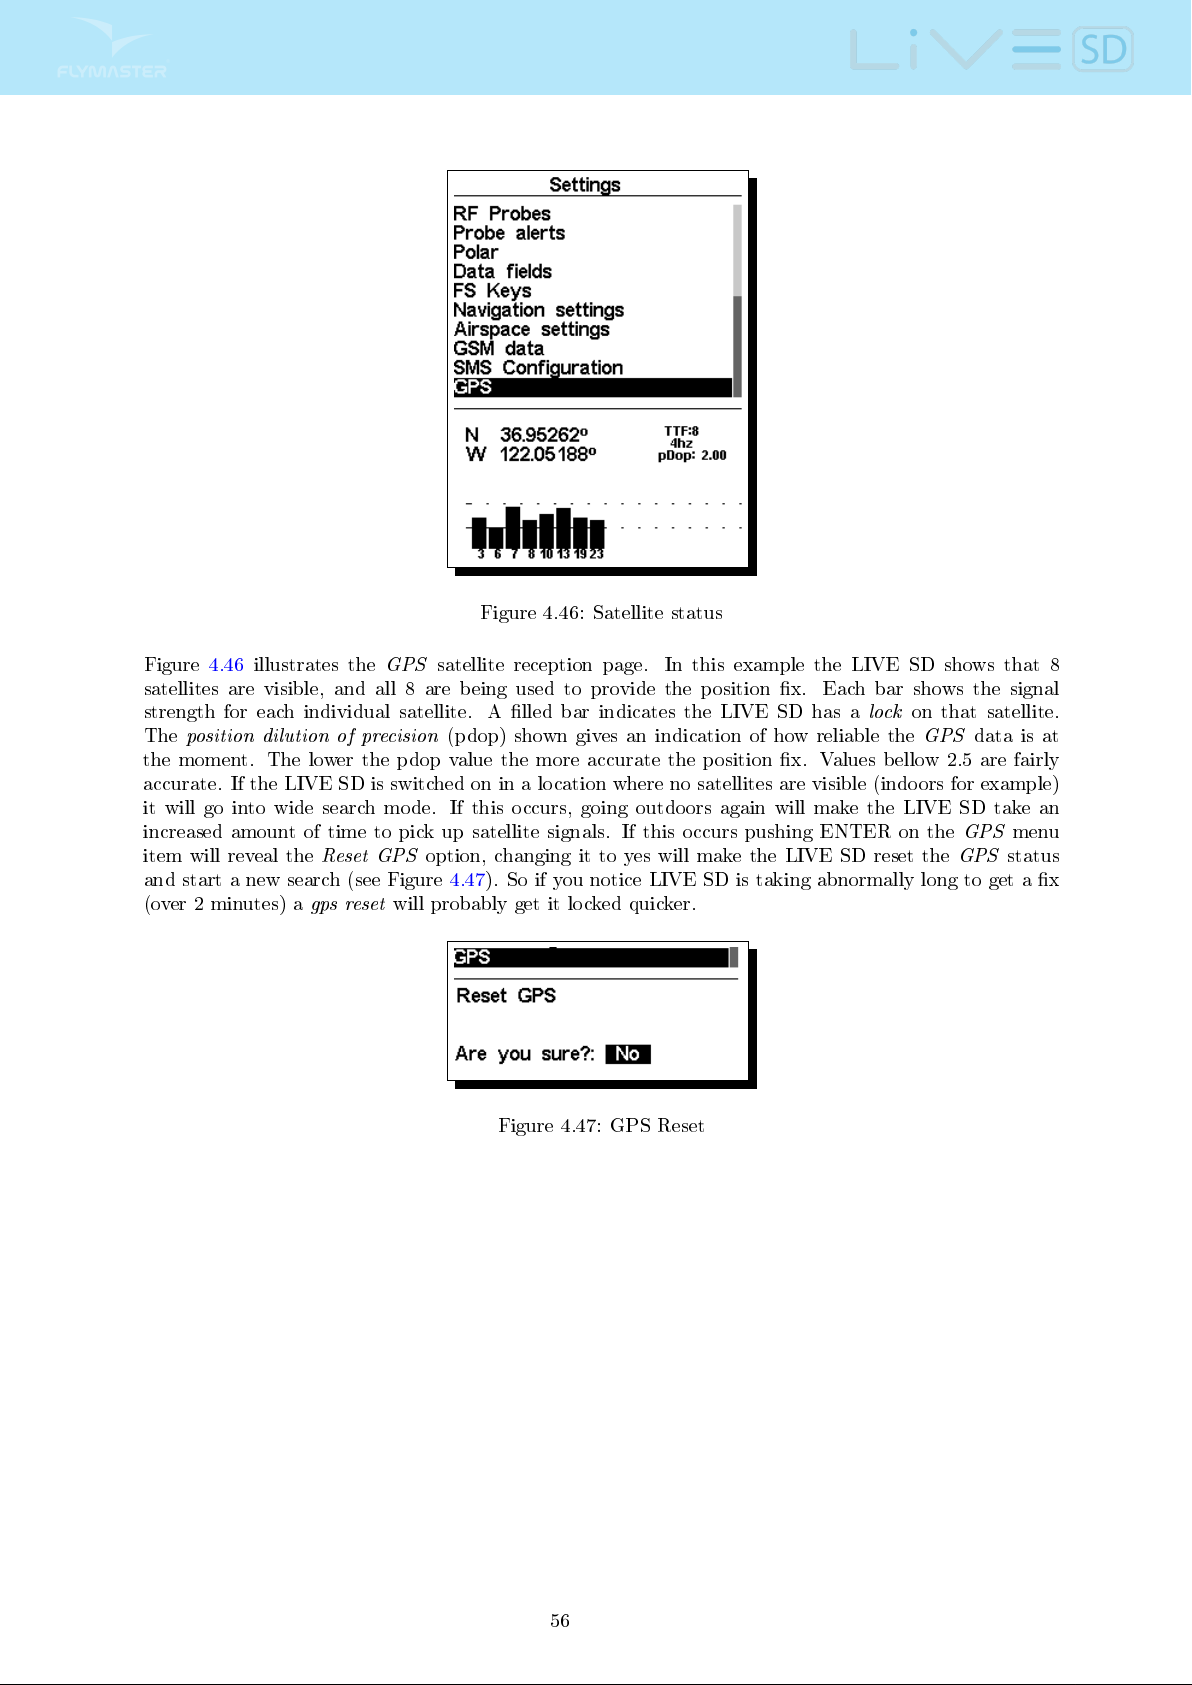
Figure 4.46: Satellite status
Figure 4.46 illustrates the
GPS
satellite reception page. In this example the LIVE SD shows that 8
satellites are visible, and all 8 are being used to provide the position x. Each bar shows the signal
strength for each individual satellite. A lled bar indicates the LIVE SD has a
The
position dilution of precision
(pdop) shown gives an indication of how reliable the
lock
on that satellite.
GPS
data is at
the moment. The lower the pdop value the more accurate the position x. Values bellow 2.5 are fairly
accurate. If the LIVE SD is switched on in a location where no satellites are visible (indoors for example)
it will go into wide search mode. If this occurs, going outdoors again will make the LIVE SD take an
increased amount of time to pick up satellite signals. If this occurs pushing ENTER on the
item will reveal the
Reset GPS
option, changing it to yes will make the LIVE SD reset the
GPS
GPS
menu
status
and start a new search (see Figure 4.47). So if you notice LIVE SD is taking abnormally long to get a x
(over 2 minutes) a
gps reset
will probably get it locked quicker.
Figure 4.47: GPS Reset
56
Page 58
5 TaskDenition
In this section we will present an example of how to set a task in your LIVE SD .
Consider the task represented in Figure 4.5, and detailed in Table 5.1.
Table 5.1: Task example
Cylinder type Time Waypoint name Map name Cylinder size
LAUNCH 12:00:00 PM LAUNCH to
START 01:00:00 PM WHALEB TP1 2 km
CYLINDER WHALEB TP2 400 m
CYLINDER SHEEP TP3 3 km
CYLINDER HEBRON TP4 6 km
CYLINDER GOOSEN TP5 2 km
END OF SPEED
SECTION
GOAL 05:00:00 PM WHALEL TP6 400m
In order to set up the task in your LIVE SD you should go trough the following steps:
1. Delete any existing task on the LIVE SD (see Section 4.1.2);
2. Add to the task, in the right order
nally
is the rst waypoint on the list. The rst
will be used to dene the landing deadline. As waypoints are entered their properties can be edited
as you enter each waypoint;
3. On the task list, select the rst occurrence of
Start Out
24 hour clock). Beware, that it is very important that the rst occurrence of
Start
gate, and that is not what is required for this task. Nothing needs to be changed for the second
occurrence of
4. Edit each of the waypoints SHEEP, HEBRON, and GOOSEN and set the distance to match the
wanted one. All these waypoints are cylinders which is the default type.
WHALEL
, set the distance to 2.000km, and the start time to 13:00. (Note that all times are in the
, otherwise the LIVE SD will assume that
twice. The LIVE SD will automatically assume
WHALEB
since the default values are the ones wanted.
WHALEL TP6 2 km
LAUNCH,WHALEB
WHALEB
WHALEB
WHALEB
twice,
SHEEP,HEBRON,GOOSEN
LAUNCH
will be used as Start, and the last
and edit it. Change the waypoint type to
needs to be completed before the start
as the takeo since it
WHALEL
WHALEB
be set as
, and
5. Edit the rst occurrence of
2.000km, and leave the
6. Edit the second occurrence of WHALEL and change its type to
to be changed since the radius is by default 400m. Continuously pressing the ENTER bottom will
make the cursor jump to the next parameter which is the time. Time should be set to 17:00 which
is the goal close time.
Upon completion of editing the task, the task list will show the distances for each leg, and the start gate
will be shown with anS, end of speed section is shown with anEand the goal shown with aG. The
completed task should look like Figure 5.1.
WHALEL
Time
with 00:00, and
and change its type to
Cone
with 0.0.
57
End of Speed Section
GOAL
. The radius does not need
, the
Size
to
Page 59
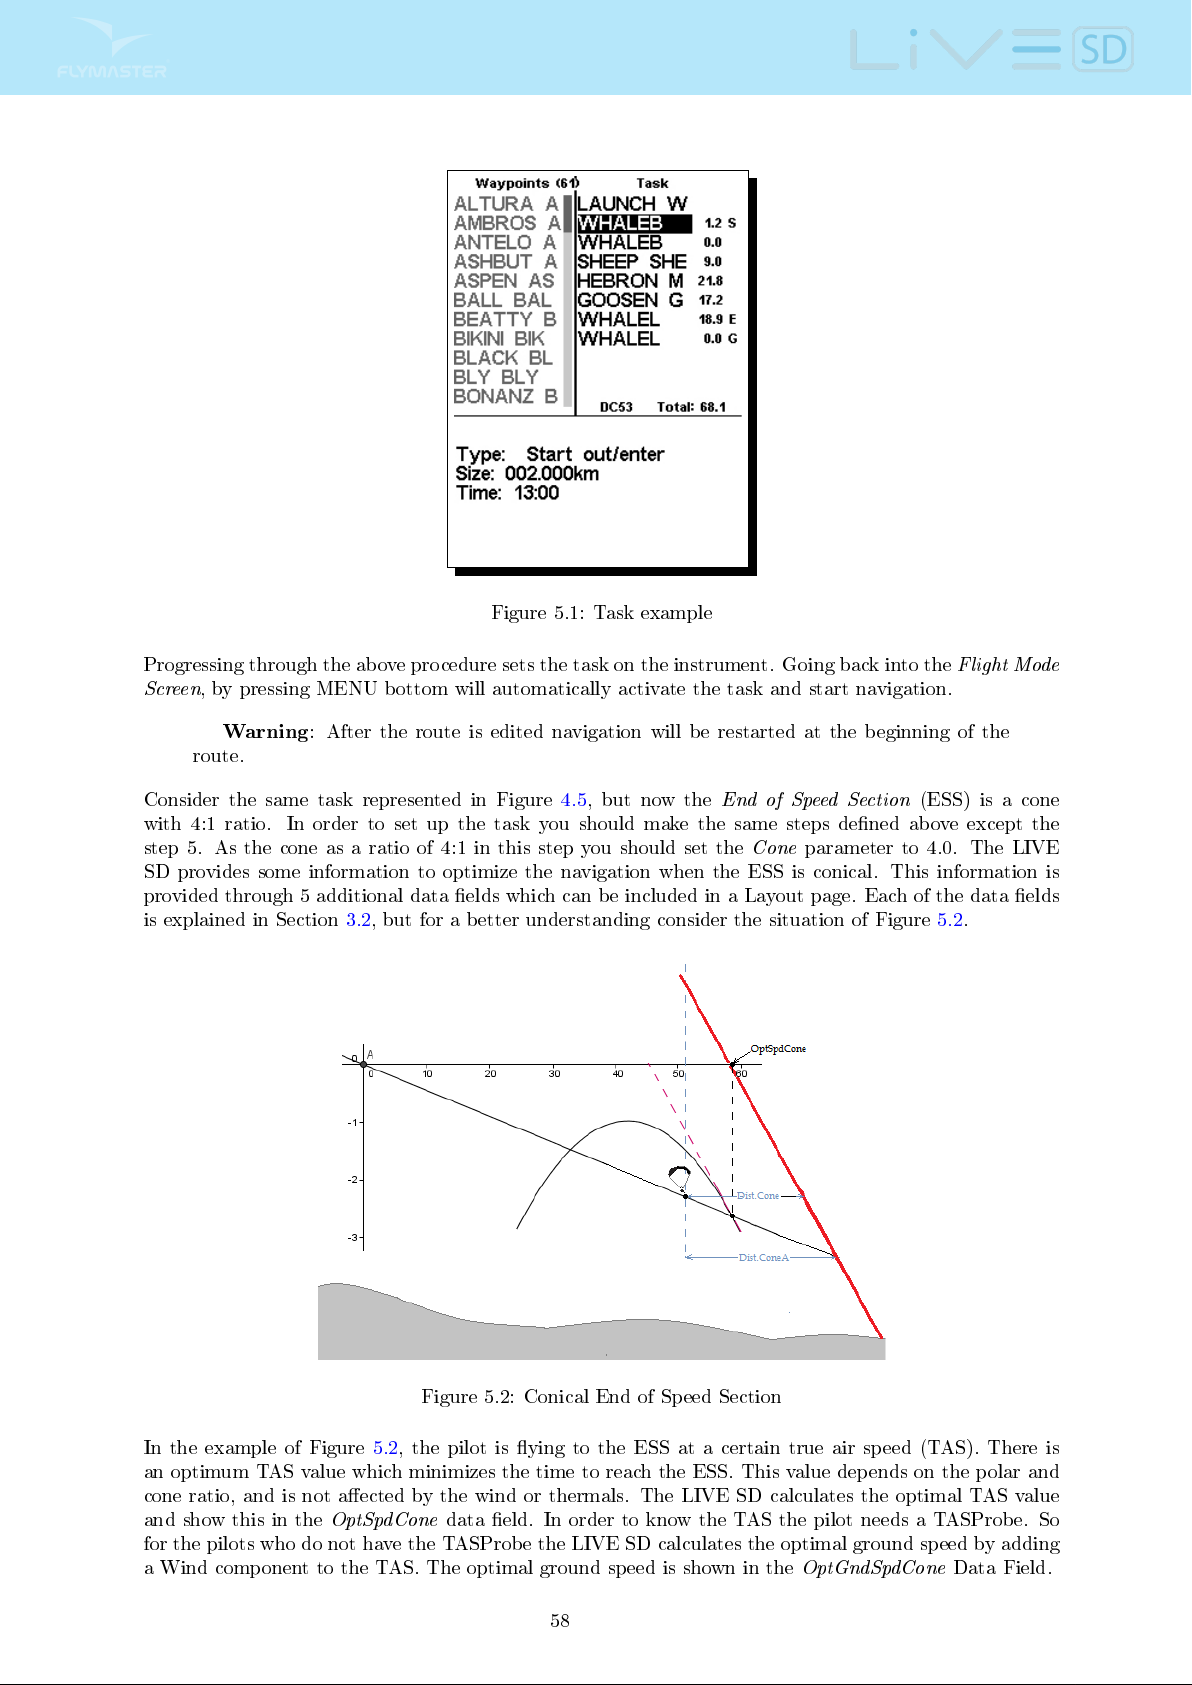
Figure 5.1: Task example
Progressing through the above procedure sets the task on the instrument. Going back into the
Screen
, by pressing MENU bottom will automatically activate the task and start navigation.
Warning
: After the route is edited navigation will be restarted at the beginning of the
Flight Mode
route.
Consider the same task represented in Figure 4.5, but now the
End of Speed Section
(ESS) is a cone
with 4:1 ratio. In order to set up the task you should make the same steps dened above except the
step 5. As the cone as a ratio of 4:1 in this step you should set the
Cone
parameter to 4.0. The LIVE
SD provides some information to optimize the navigation when the ESS is conical. This information is
provided through 5 additional data elds which can be included in a Layout page. Each of the data elds
is explained in Section 3.2, but for a better understanding consider the situation of Figure 5.2.
Figure 5.2: Conical End of Speed Section
In the example of Figure 5.2, the pilot is ying to the ESS at a certain true air speed (TAS). There is
an optimum TAS value which minimizes the time to reach the ESS. This value depends on the polar and
cone ratio, and is not aected by the wind or thermals. The LIVE SD calculates the optimal TAS value
and show this in the
OptSpdCone
data eld. In order to know the TAS the pilot needs a TASProbe. So
for the pilots who do not have the TASProbe the LIVE SD calculates the optimal ground speed by adding
a Wind component to the TAS. The optimal ground speed is shown in the
OptGndSpdCone
Data Field.
58
Page 60
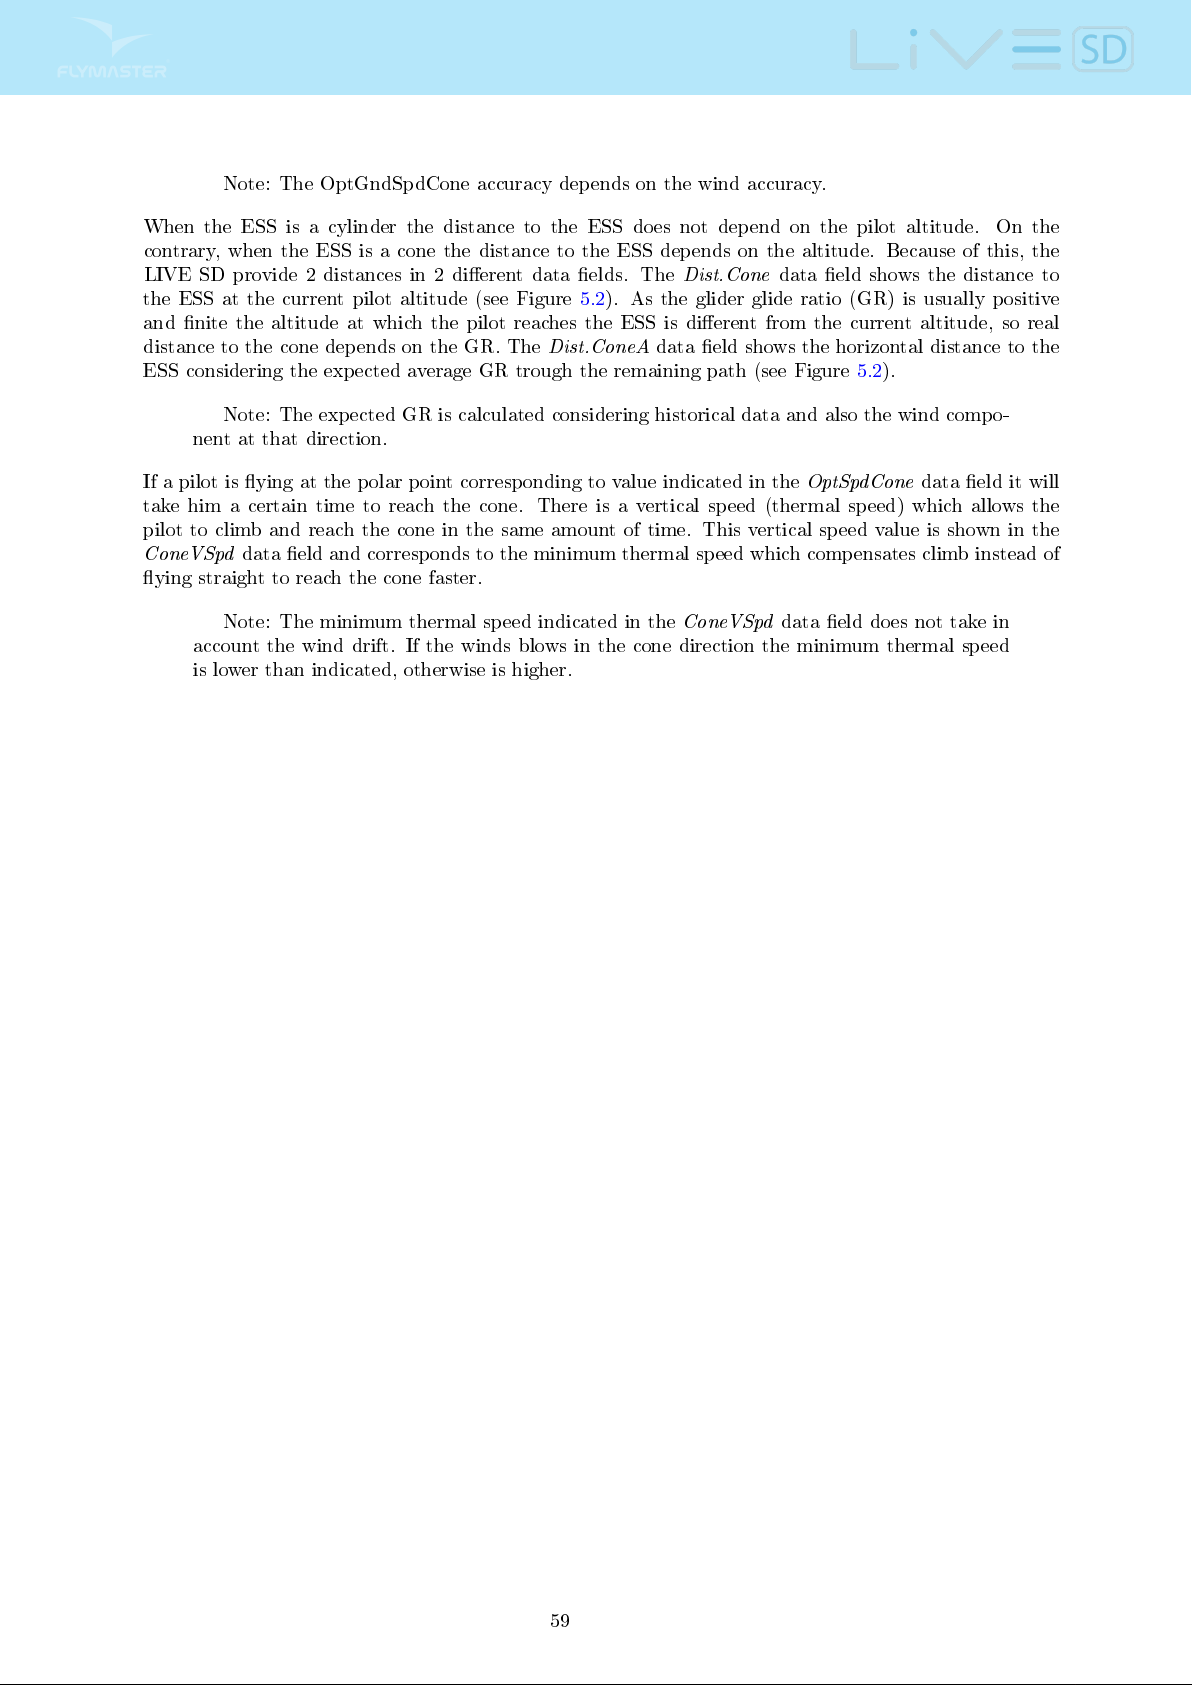
Note: The OptGndSpdCone accuracy depends on the wind accuracy.
When the ESS is a cylinder the distance to the ESS does not depend on the pilot altitude. On the
contrary, when the ESS is a cone the distance to the ESS depends on the altitude. Because of this, the
LIVE SD provide 2 distances in 2 dierent data elds. The
Dist.Cone
data eld shows the distance to
the ESS at the current pilot altitude (see Figure 5.2). As the glider glide ratio (GR) is usually positive
and nite the altitude at which the pilot reaches the ESS is dierent from the current altitude, so real
distance to the cone depends on the GR. The
Dist.ConeA
data eld shows the horizontal distance to the
ESS considering the expected average GR trough the remaining path (see Figure 5.2).
Note: The expected GR is calculated considering historical data and also the wind compo-
nent at that direction.
If a pilot is ying at the polar point corresponding to value indicated in the
OptSpdCone
data eld it will
take him a certain time to reach the cone. There is a vertical speed (thermal speed) which allows the
pilot to climb and reach the cone in the same amount of time. This vertical speed value is shown in the
ConeVSpd
data eld and corresponds to the minimum thermal speed which compensates climb instead of
ying straight to reach the cone faster.
Note: The minimum thermal speed indicated in the
ConeVSpd
data eld does not take in
account the wind drift. If the winds blows in the cone direction the minimum thermal speed
is lower than indicated, otherwise is higher.
59
Page 61
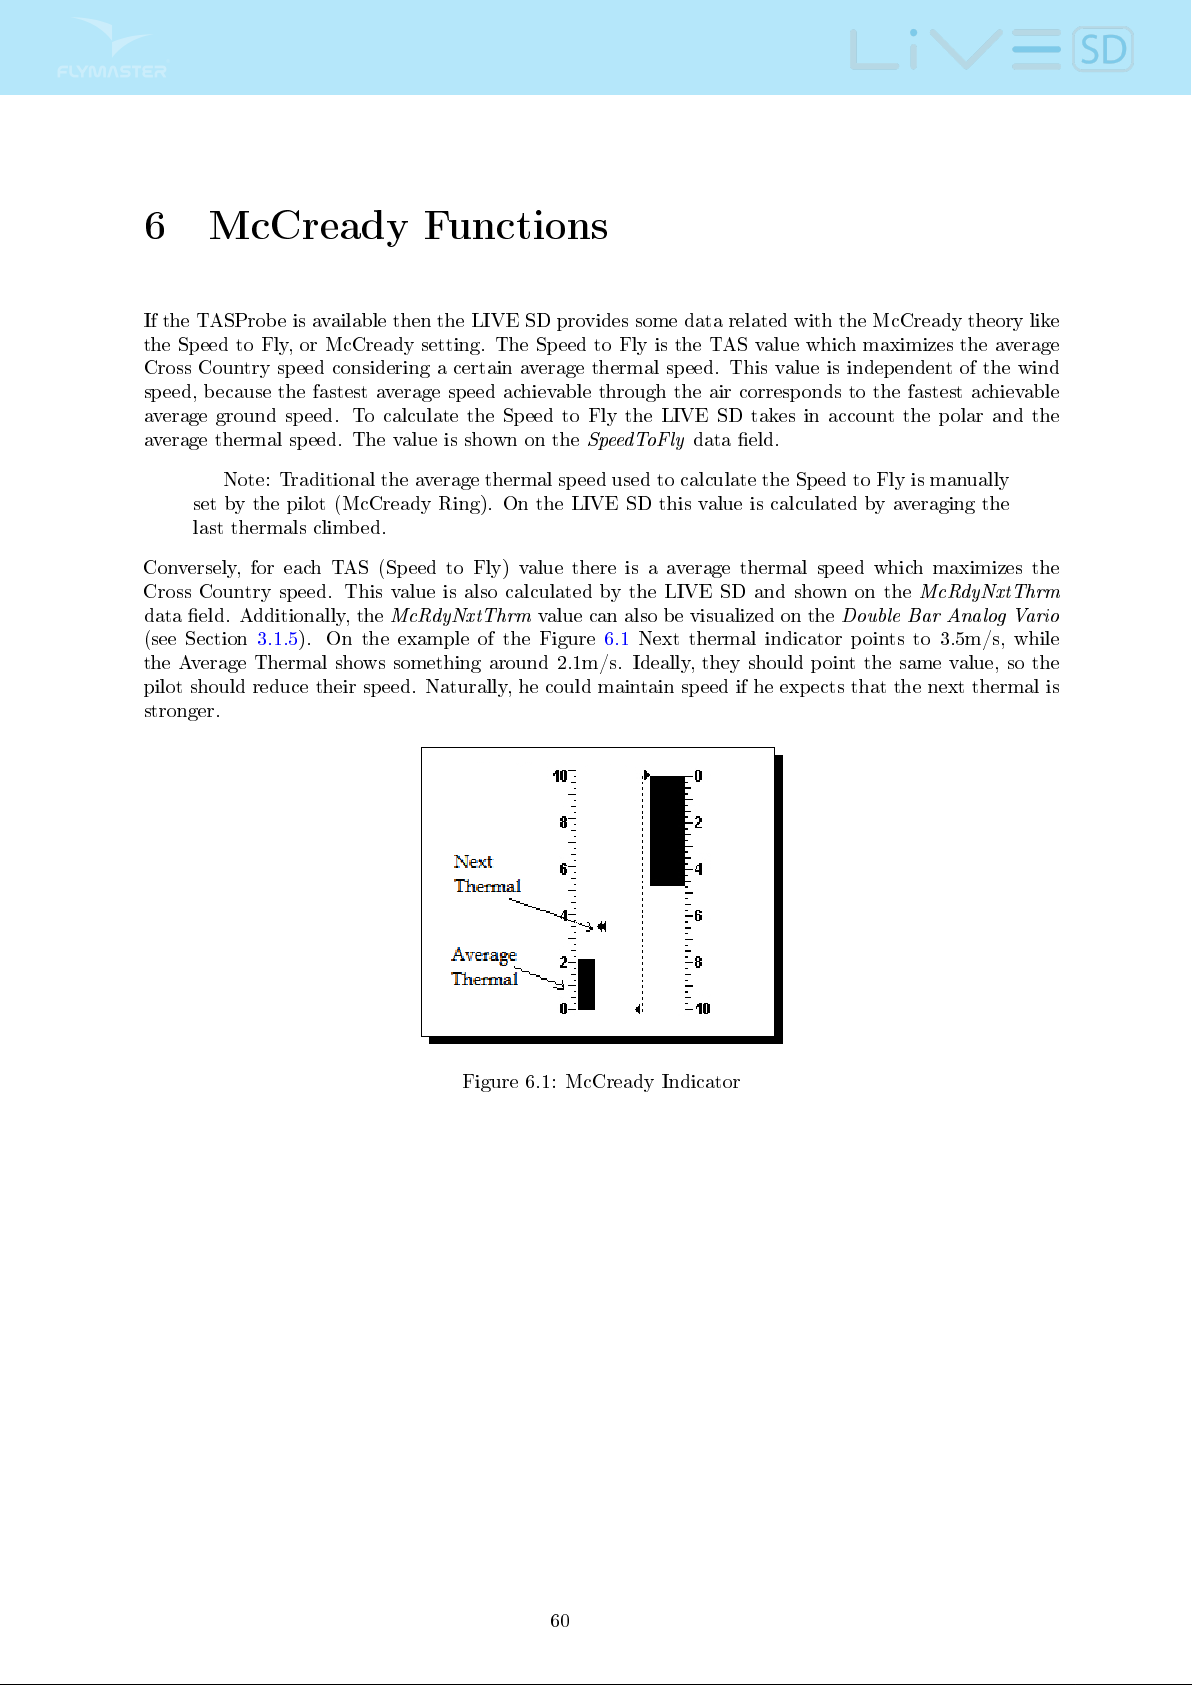
6 McCready Functions
If the TASProbe is available then the LIVE SD provides some data related with the McCready theory like
the Speed to Fly, or McCready setting. The Speed to Fly is the TAS value which maximizes the average
Cross Country speed considering a certain average thermal speed. This value is independent of the wind
speed, because the fastest average speed achievable through the air corresponds to the fastest achievable
average ground speed. To calculate the Speed to Fly the LIVE SD takes in account the polar and the
average thermal speed. The value is shown on the
Note: Traditional the average thermal speed used to calculate the Speed to Fly is manually
set by the pilot (McCready Ring). On the LIVE SD this value is calculated by averaging the
last thermals climbed.
Conversely, for each TAS (Speed to Fly) value there is a average thermal speed which maximizes the
Cross Country speed. This value is also calculated by the LIVE SD and shown on the
data eld. Additionally, the
(see Section 3.1.5). On the example of the Figure 6.1 Next thermal indicator points to 3.5m/s, while
the Average Thermal shows something around 2.1m/s. Ideally, they should point the same value, so the
pilot should reduce their speed. Naturally, he could maintain speed if he expects that the next thermal is
stronger.
McRdyNxtThrm
SpeedToFly
value can also be visualized on the
data eld.
McRdyNxtThrm
Double Bar Analog Vario
Figure 6.1: McCready Indicator
60
Page 62
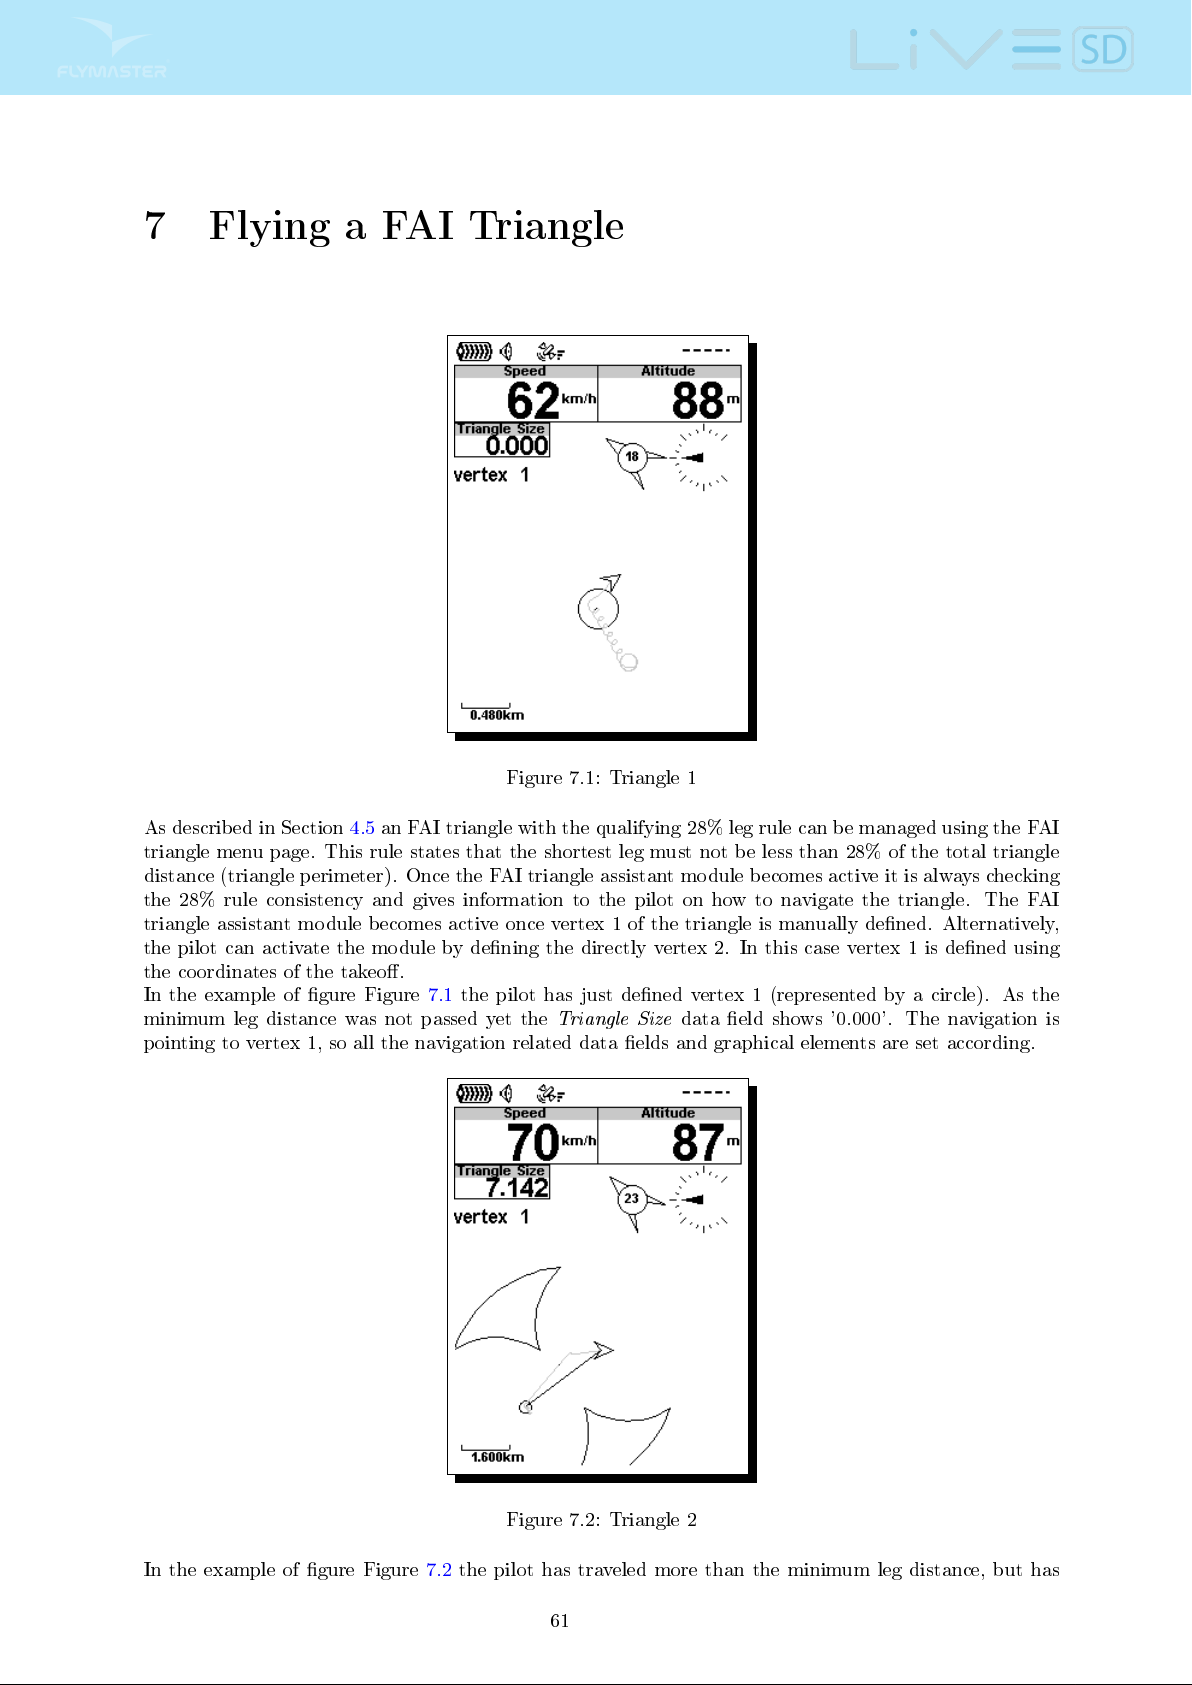
7 Flying a FAI Triangle
Figure 7.1: Triangle 1
As described in Section 4.5 an FAI triangle with the qualifying 28% leg rule can be managed using the FAI
triangle menu page. This rule states that the shortest leg must not be less than 28% of the total triangle
distance (triangle perimeter). Once the FAI triangle assistant module becomes active it is always checking
the 28% rule consistency and gives information to the pilot on how to navigate the triangle. The FAI
triangle assistant module becomes active once vertex 1 of the triangle is manually dened. Alternatively,
the pilot can activate the module by dening the directly vertex 2. In this case vertex 1 is dened using
the coordinates of the takeo.
In the example of gure Figure 7.1 the pilot has just dened vertex 1 (represented by a circle). As the
minimum leg distance was not passed yet the
pointing to vertex 1, so all the navigation related data elds and graphical elements are set according.
Triangle Size
data eld shows '0.000'. The navigation is
Figure 7.2: Triangle 2
In the example of gure Figure 7.2 the pilot has traveled more than the minimum leg distance, but has
61
Page 63
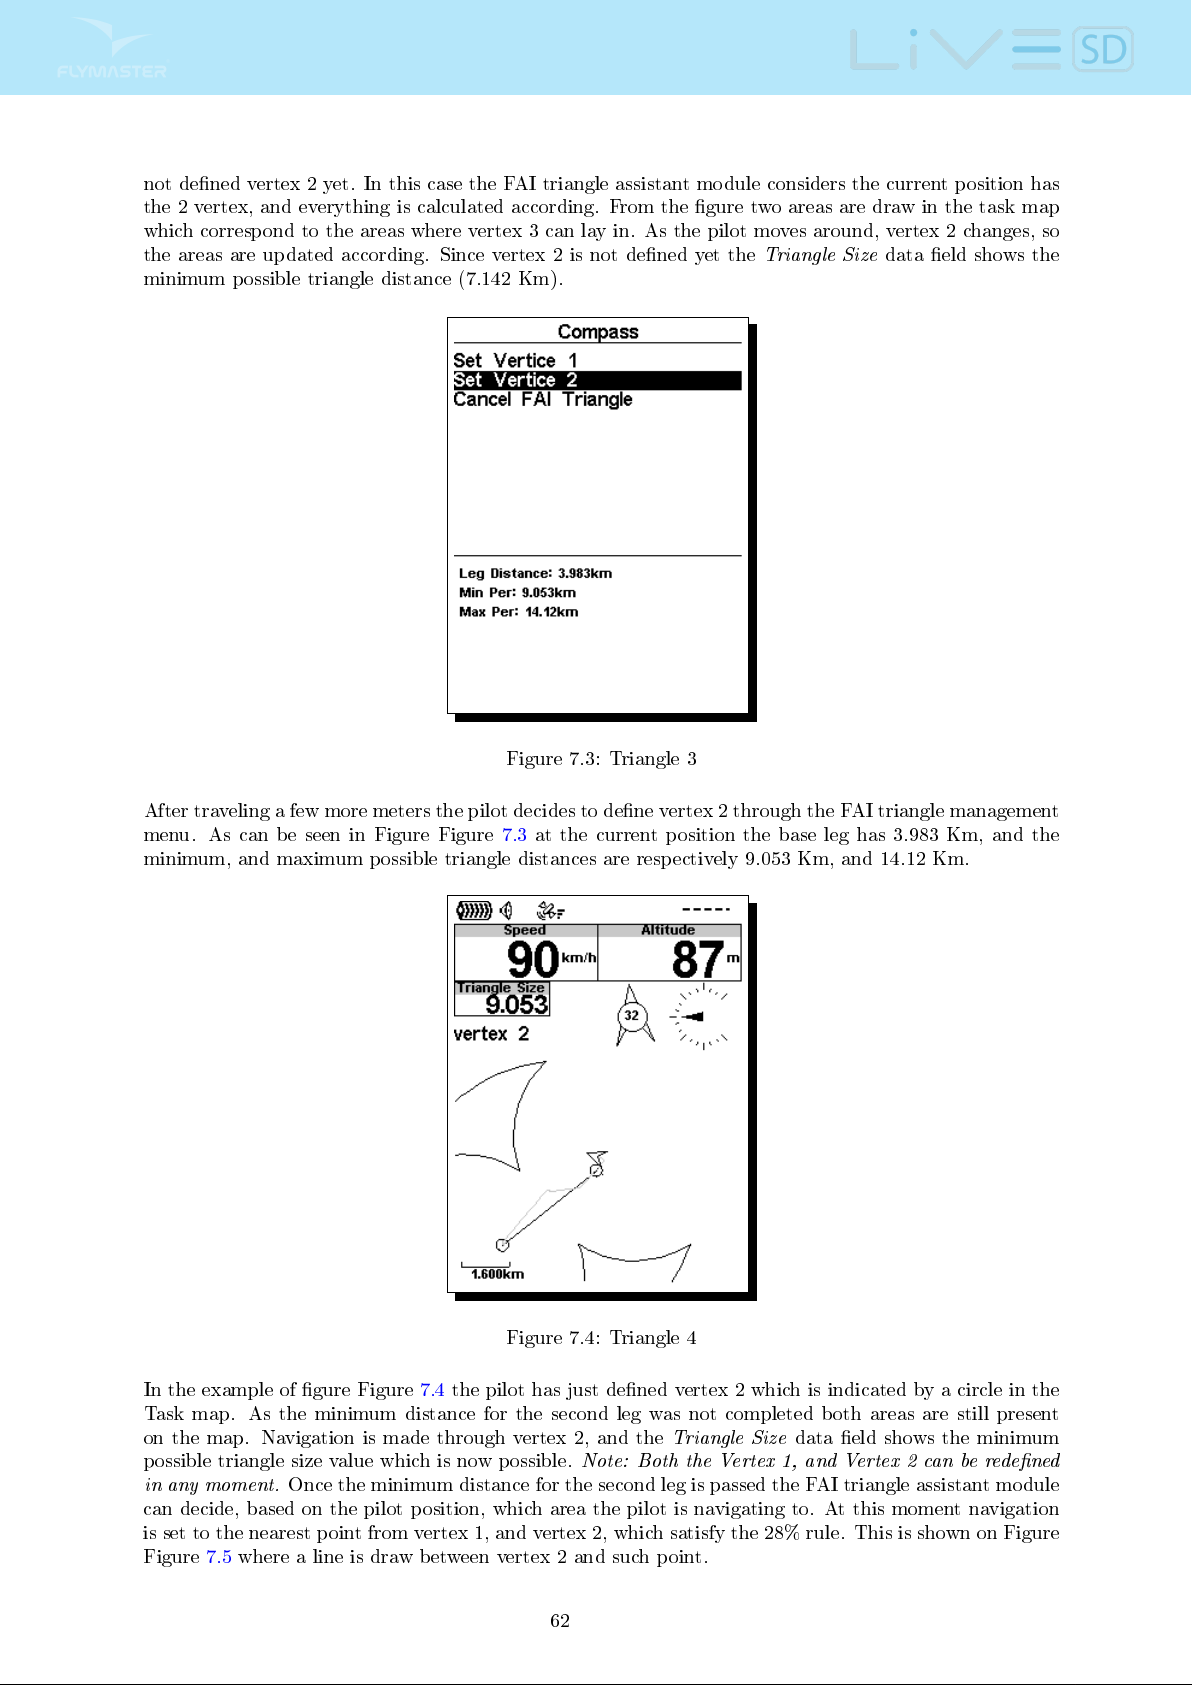
not dened vertex 2 yet. In this case the FAI triangle assistant module considers the current position has
the 2 vertex, and everything is calculated according. From the gure two areas are draw in the task map
which correspond to the areas where vertex 3 can lay in. As the pilot moves around, vertex 2 changes, so
the areas are updated according. Since vertex 2 is not dened yet the
Triangle Size
data eld shows the
minimum possible triangle distance (7.142 Km).
Figure 7.3: Triangle 3
After traveling a few more meters the pilot decides to dene vertex 2 through the FAI triangle management
menu. As can be seen in Figure Figure 7.3 at the current position the base leg has 3.983 Km, and the
minimum, and maximum possible triangle distances are respectively 9.053 Km, and 14.12 Km.
Figure 7.4: Triangle 4
In the example of gure Figure 7.4 the pilot has just dened vertex 2 which is indicated by a circle in the
Task map. As the minimum distance for the second leg was not completed both areas are still present
on the map. Navigation is made through vertex 2, and the
possible triangle size value which is now possible.
in any moment.
Once the minimum distance for the second leg is passed the FAI triangle assistant module
Note: Both the Vertex 1, and Vertex 2 can be redened
Triangle Size
data eld shows the minimum
can decide, based on the pilot position, which area the pilot is navigating to. At this moment navigation
is set to the nearest point from vertex 1, and vertex 2, which satisfy the 28% rule. This is shown on Figure
Figure 7.5 where a line is draw between vertex 2 and such point.
62
Page 64
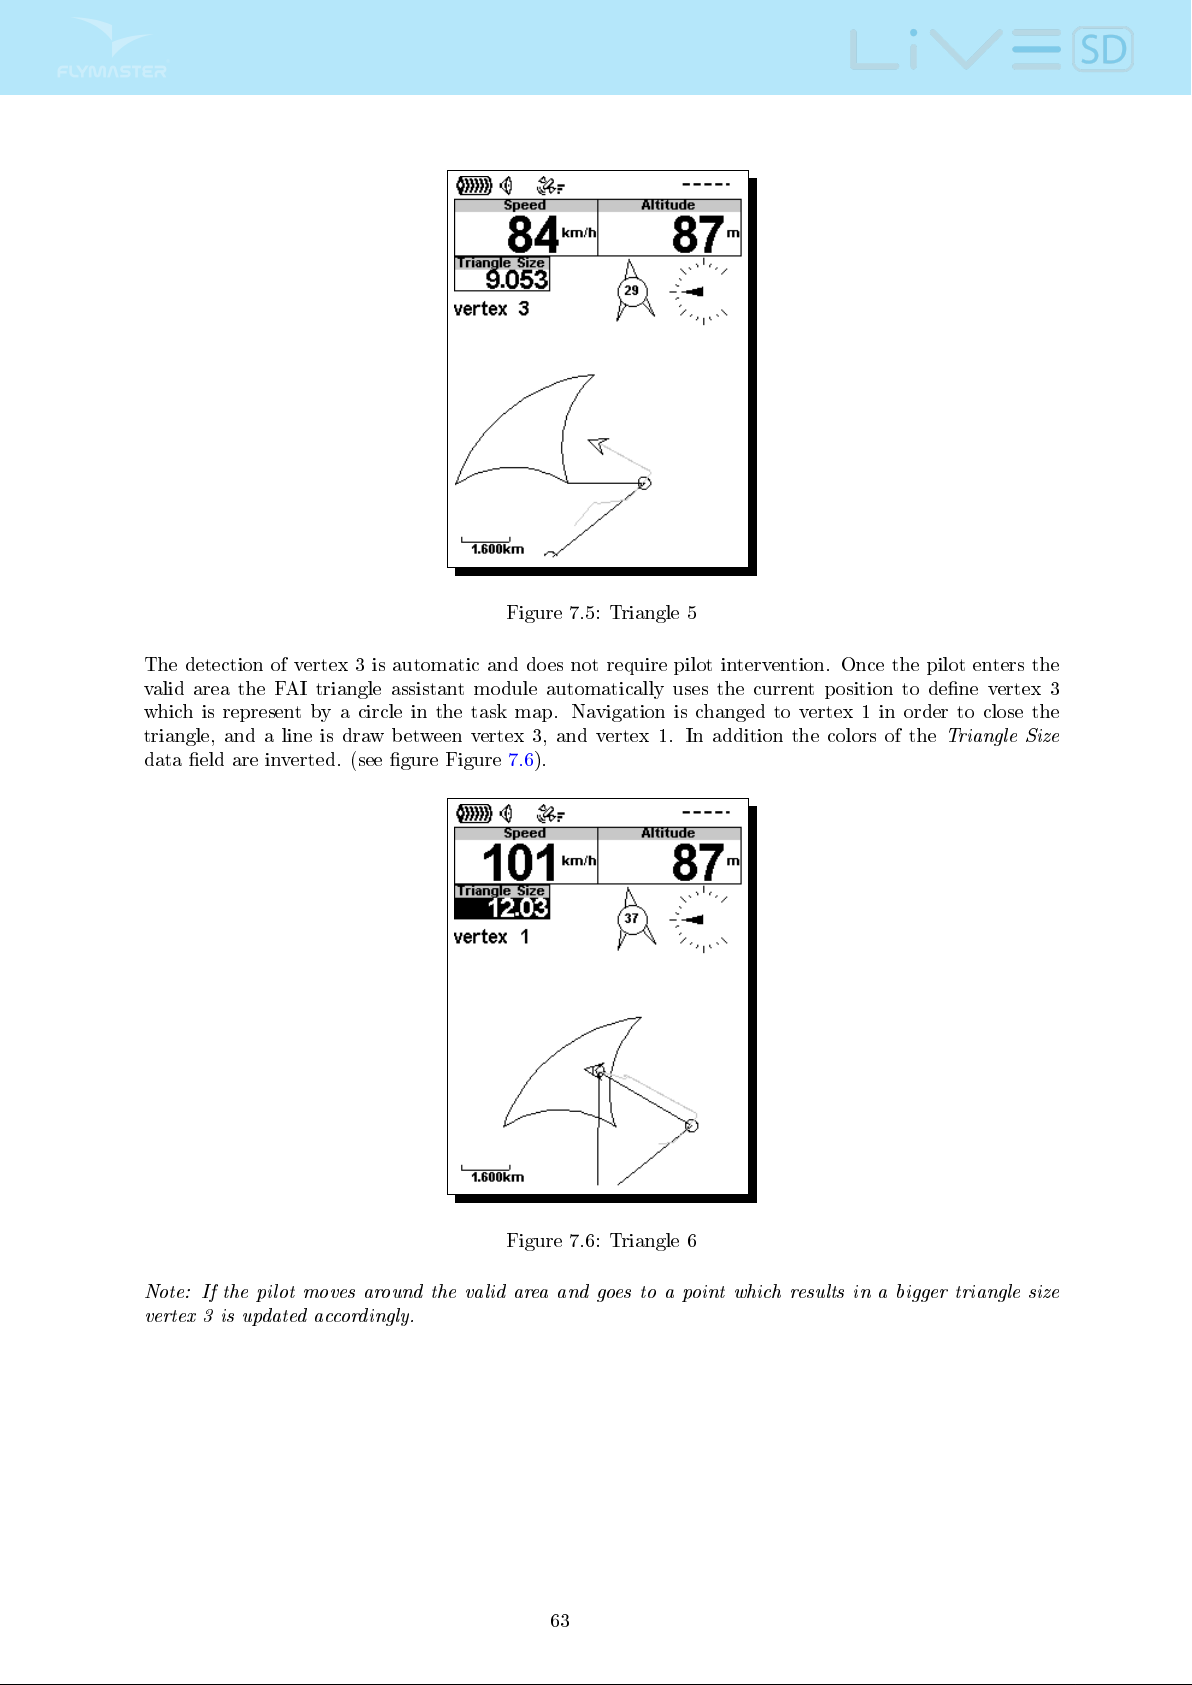
Figure 7.5: Triangle 5
The detection of vertex 3 is automatic and does not require pilot intervention. Once the pilot enters the
valid area the FAI triangle assistant module automatically uses the current position to dene vertex 3
which is represent by a circle in the task map. Navigation is changed to vertex 1 in order to close the
triangle, and a line is draw between vertex 3, and vertex 1. In addition the colors of the
Triangle Size
data eld are inverted. (see gure Figure 7.6).
Figure 7.6: Triangle 6
Note: If the pilot moves around the valid area and goes to a point which results in a bigger triangle size
vertex 3 is updated accordingly.
63
Page 65
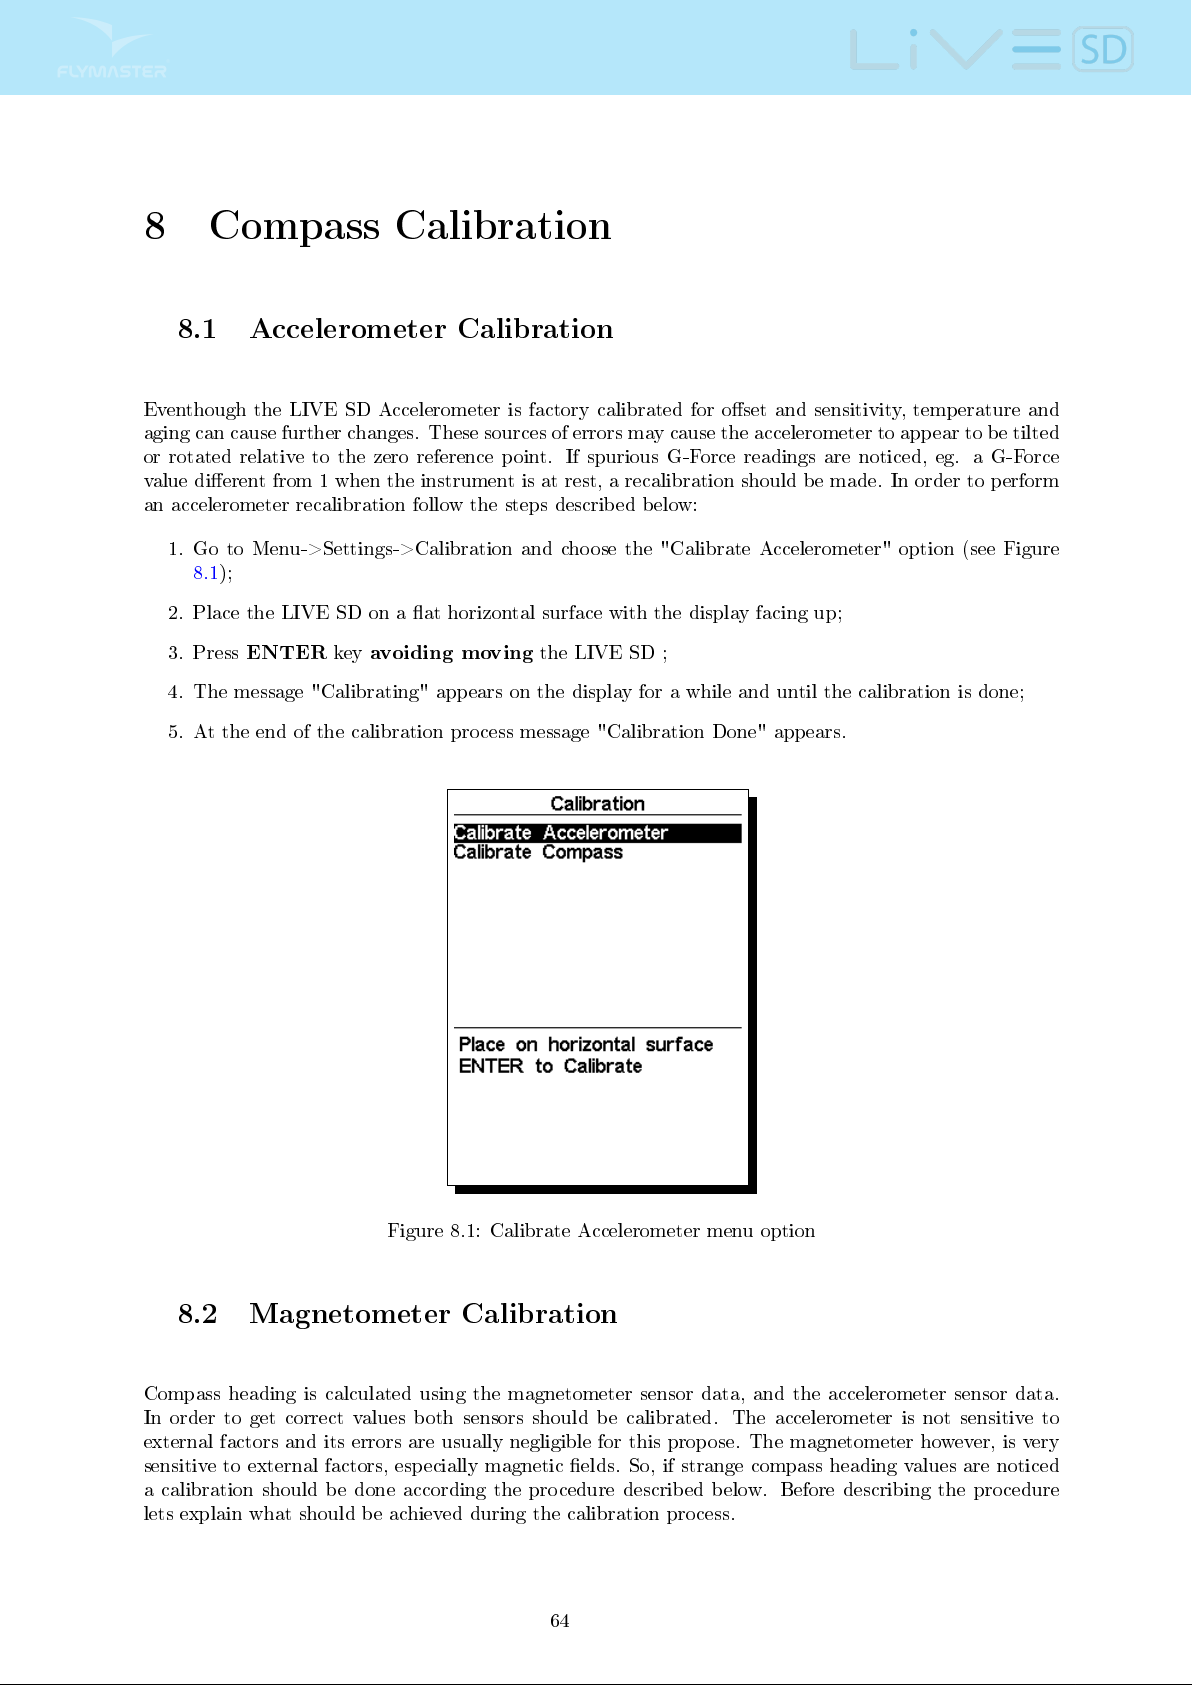
8 Compass Calibration
8.1 Accelerometer Calibration
Eventhough the LIVE SD Accelerometer is factory calibrated for oset and sensitivity, temperature and
aging can cause further changes. These sources of errors may cause the accelerometer to appear to be tilted
or rotated relative to the zero reference point. If spurious G-Force readings are noticed, eg. a G-Force
value dierent from 1 when the instrument is at rest, a recalibration should be made. In order to perform
an accelerometer recalibration follow the steps described below:
1. Go to Menu->Settings->Calibration and choose the "Calibrate Accelerometer" option (see Figure
8.1);
2. Place the LIVE SD on a at horizontal surface with the display facing up;
3. Press
4. The message "Calibrating" appears on the display for a while and until the calibration is done;
5. At the end of the calibration process message "Calibration Done" appears.
ENTER
key
avoiding moving
Figure 8.1: Calibrate Accelerometer menu option
the LIVE SD ;
8.2 Magnetometer Calibration
Compass heading is calculated using the magnetometer sensor data, and the accelerometer sensor data.
In order to get correct values both sensors should be calibrated. The accelerometer is not sensitive to
external factors and its errors are usually negligible for this propose. The magnetometer however, is very
sensitive to external factors, especially magnetic elds. So, if strange compass heading values are noticed
a calibration should be done according the procedure described below. Before describing the procedure
lets explain what should be achieved during the calibration process.
64
Page 66
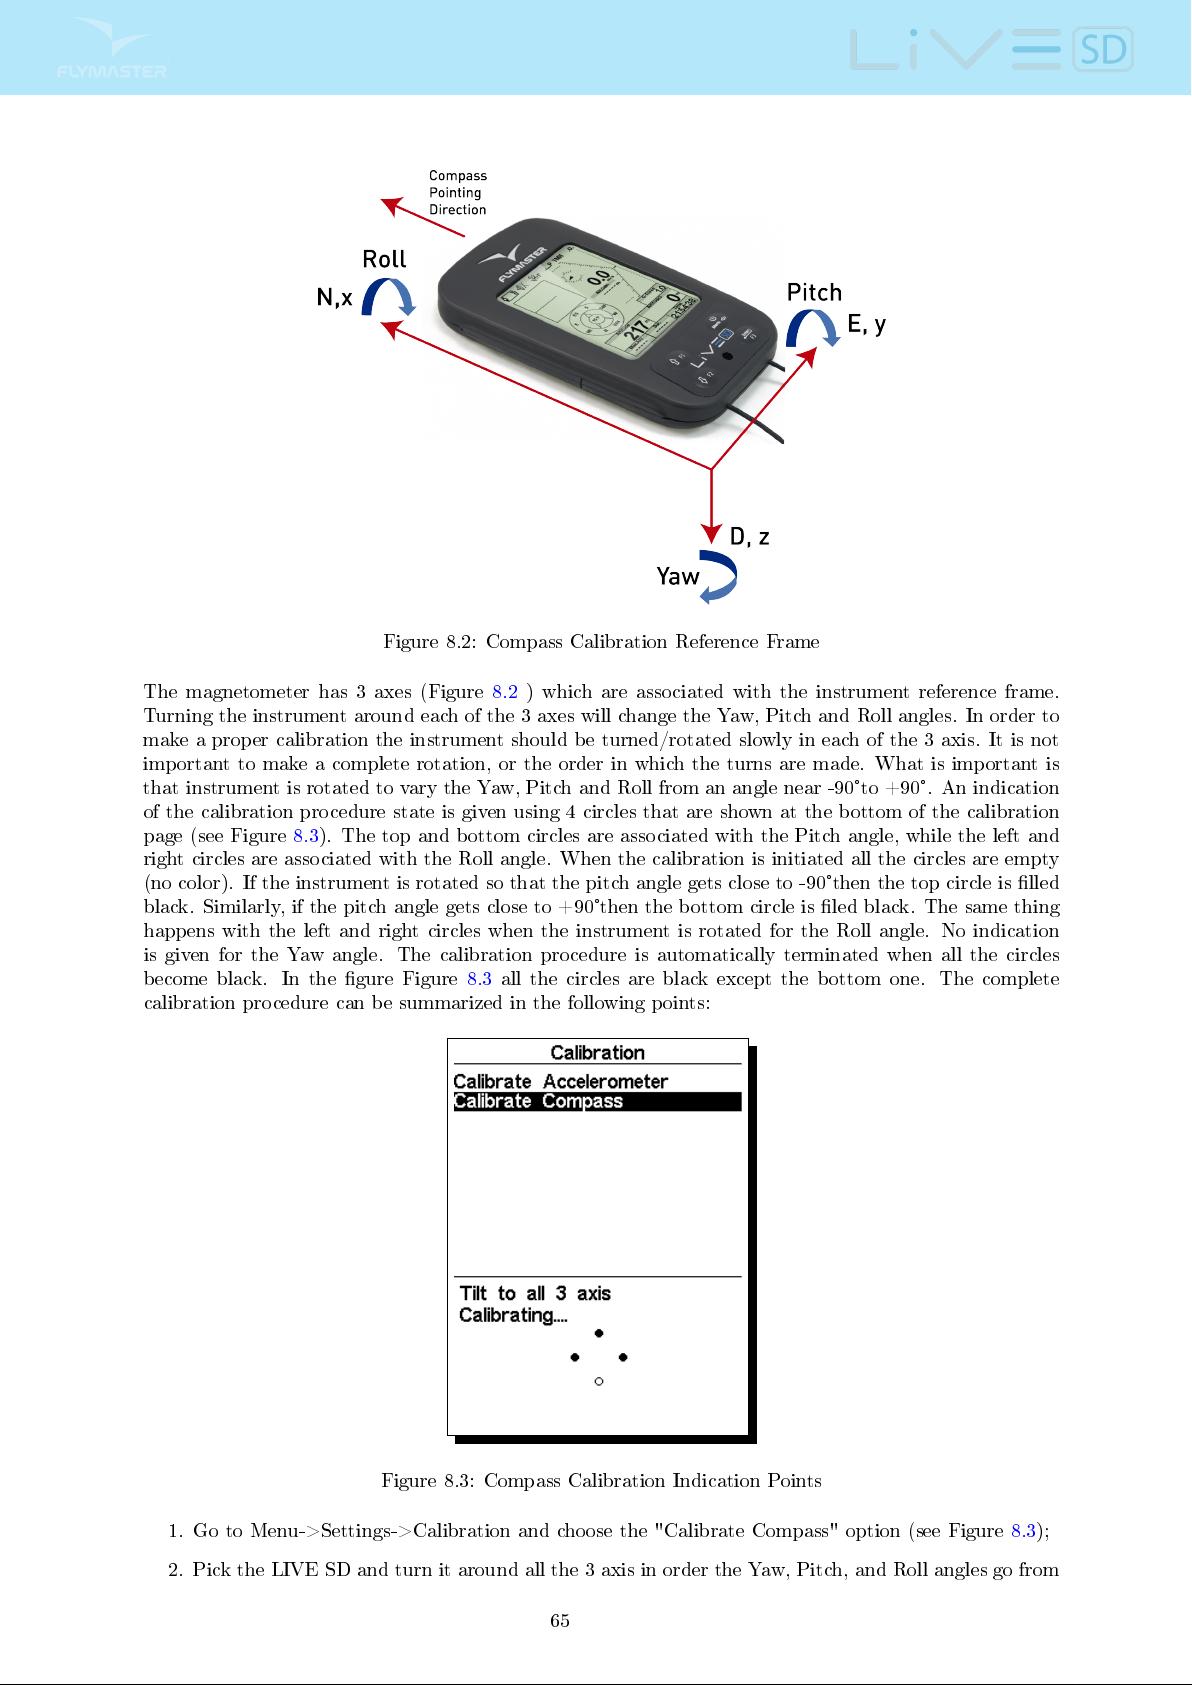
Figure 8.2: Compass Calibration Reference Frame
The magnetometer has 3 axes (Figure 8.2 ) which are associated with the instrument reference frame.
Turning the instrument around each of the 3 axes will change the Yaw, Pitch and Roll angles. In order to
make a proper calibration the instrument should be turned/rotated slowly in each of the 3 axis. It is not
important to make a complete rotation, or the order in which the turns are made. What is important is
that instrument is rotated to vary the Yaw, Pitch and Roll from an angle near -90°to +90°. An indication
of the calibration procedure state is given using 4 circles that are shown at the bottom of the calibration
page (see Figure 8.3). The top and bottom circles are associated with the Pitch angle, while the left and
right circles are associated with the Roll angle. When the calibration is initiated all the circles are empty
(no color). If the instrument is rotated so that the pitch angle gets close to -90°then the top circle is lled
black. Similarly, if the pitch angle gets close to +90°then the bottom circle is led black. The same thing
happens with the left and right circles when the instrument is rotated for the Roll angle. No indication
is given for the Yaw angle. The calibration procedure is automatically terminated when all the circles
become black. In the gure Figure 8.3 all the circles are black except the bottom one. The complete
calibration procedure can be summarized in the following points:
Figure 8.3: Compass Calibration Indication Points
1. Go to Menu->Settings->Calibration and choose the "Calibrate Compass" option (see Figure 8.3);
2. Pick the LIVE SD and turn it around all the 3 axis in order the Yaw, Pitch, and Roll angles go from
65
Page 67
-90°to +90°. You can accomplish this by performing a movement similar to the one used to calibrate
the iphone;
3. If the movement is correctly made the all the 4 circles will become black and the calibration process
automatically stop;
4. The end of the calibration process is indicated by the message "Calibration Done"'
66
Page 68
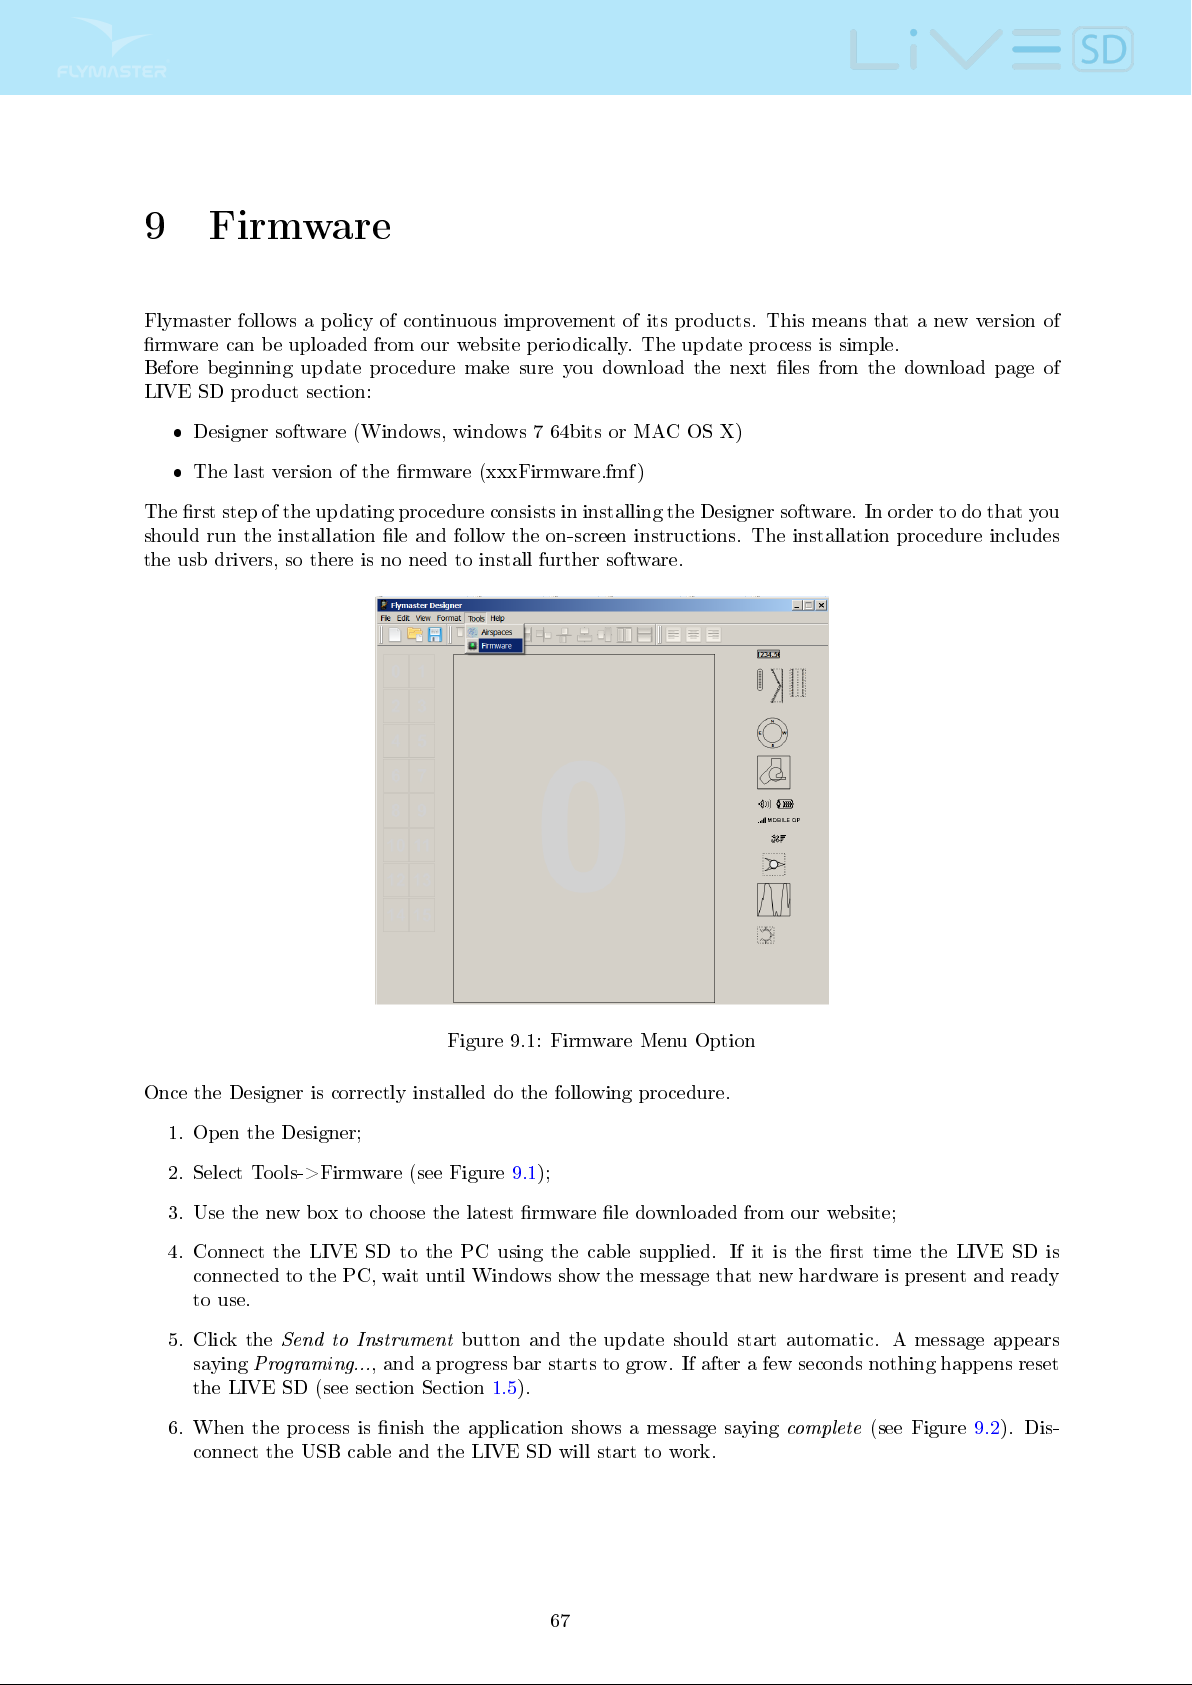
9 Firmware
Flymaster follows a policy of continuous improvement of its products. This means that a new version of
rmware can be uploaded from our website periodically. The update process is simple.
Before beginning update procedure make sure you download the next les from the download page of
LIVE SD product section:
Designer software (Windows, windows 7 64bits or MAC OS X)
The last version of the rmware (xxxFirmware.fmf)
The rst step of the updating procedure consists in installing the Designer software. In order to do that you
should run the installation le and follow the on-screen instructions. The installation procedure includes
the usb drivers, so there is no need to install further software.
Figure 9.1: Firmware Menu Option
Once the Designer is correctly installed do the following procedure.
1. Open the Designer;
2. Select Tools->Firmware (see Figure 9.1);
3. Use the new box to choose the latest rmware le downloaded from our website;
4. Connect the LIVE SD to the PC using the cable supplied. If it is the rst time the LIVE SD is
connected to the PC, wait until Windows show the message that new hardware is present and ready
to use.
5. Click the
saying
the LIVE SD (see section Section 1.5).
6. When the process is nish the application shows a message saying
connect the USB cable and the LIVE SD will start to work.
Send to Instrument
Programing...
, and a progress bar starts to grow. If after a few seconds nothing happens reset
button and the update should start automatic. A message appears
complete
67
(see Figure 9.2). Dis-
Page 69
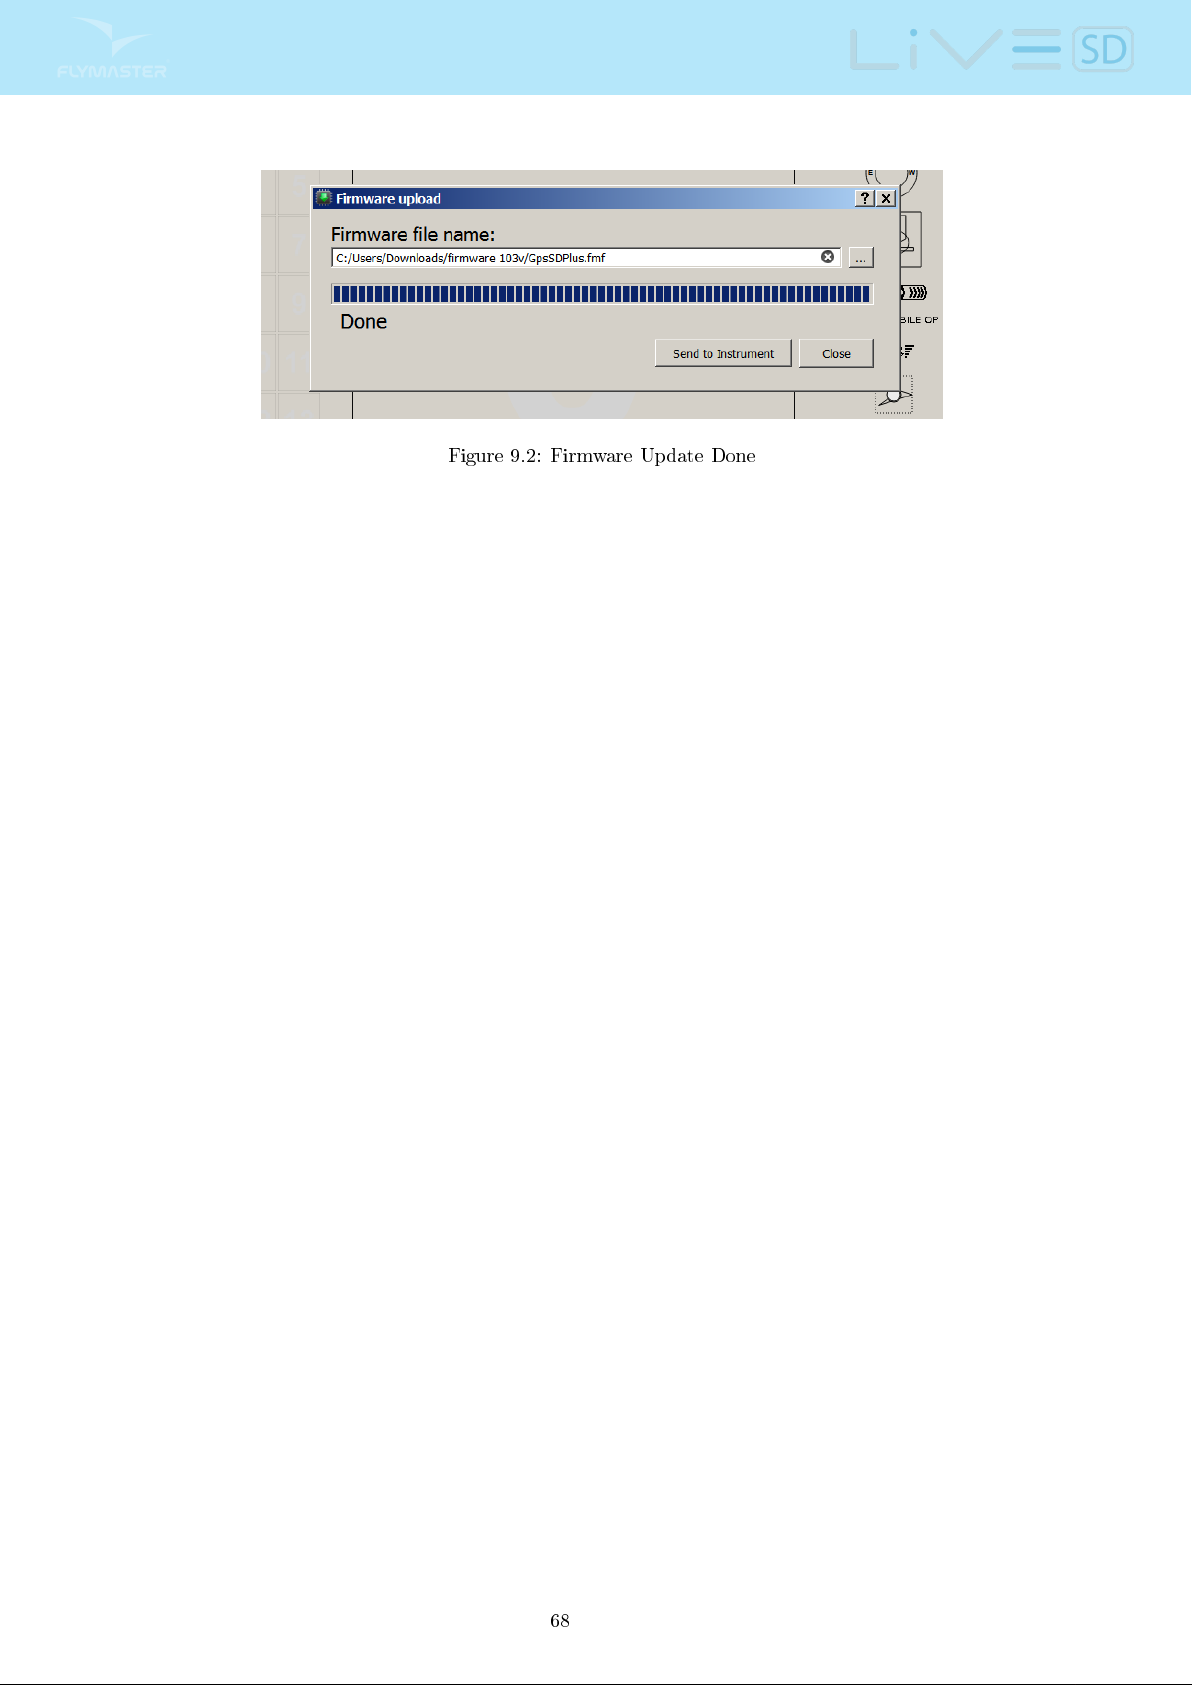
Figure 9.2: Firmware Update Done
68
Page 70
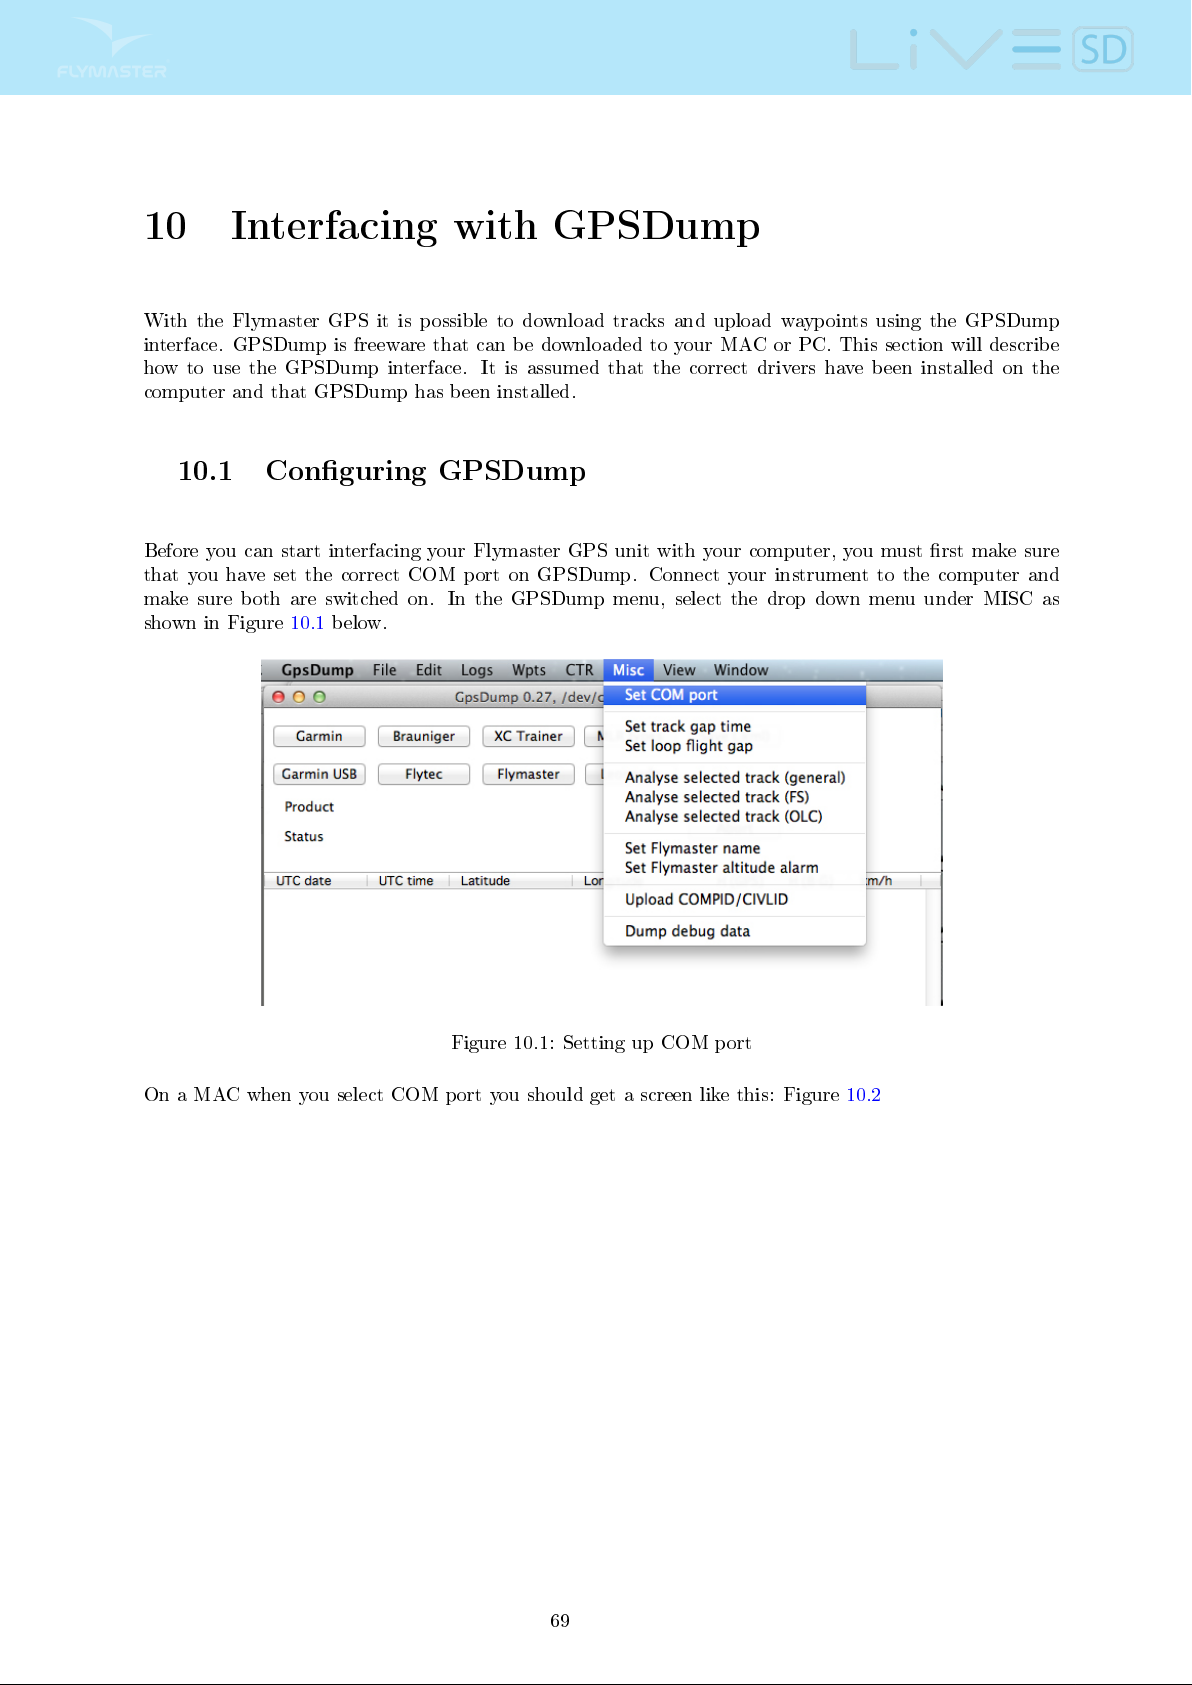
10 Interfacing with GPSDump
With the Flymaster GPS it is possible to download tracks and upload waypoints using the GPSDump
interface. GPSDump is freeware that can be downloaded to your MAC or PC. This section will describe
how to use the GPSDump interface. It is assumed that the correct drivers have been installed on the
computer and that GPSDump has been installed.
10.1 Conguring GPSDump
Before you can start interfacing your Flymaster GPS unit with your computer, you must rst make sure
that you have set the correct COM port on GPSDump. Connect your instrument to the computer and
make sure both are switched on. In the GPSDump menu, select the drop down menu under MISC as
shown in Figure 10.1 below.
Figure 10.1: Setting up COM port
On a MAC when you select COM port you should get a screen like this: Figure 10.2
69
Page 71
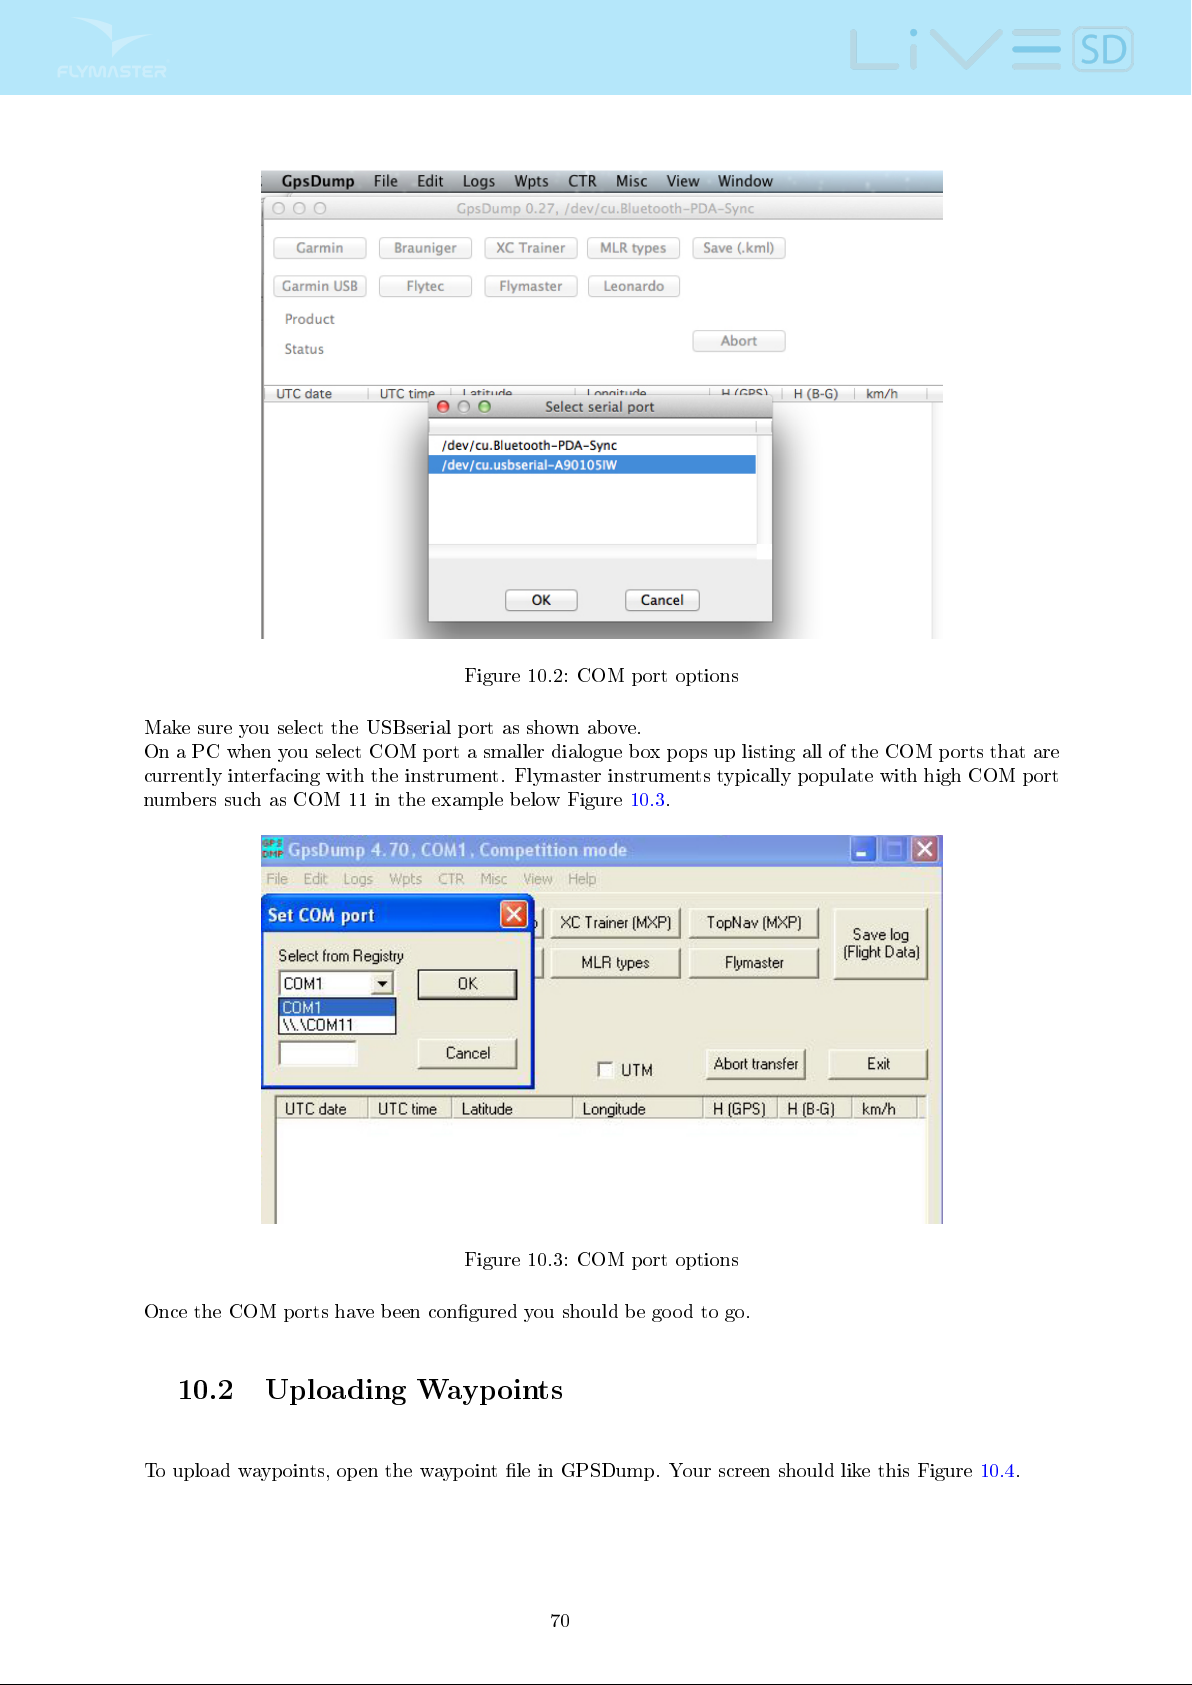
Figure 10.2: COM port options
Make sure you select the USBserial port as shown above.
On a PC when you select COM port a smaller dialogue box pops up listing all of the COM ports that are
currently interfacing with the instrument. Flymaster instruments typically populate with high COM port
numbers such as COM 11 in the example below Figure 10.3.
Figure 10.3: COM port options
Once the COM ports have been congured you should be good to go.
10.2 Uploading Waypoints
To upload waypoints, open the waypoint le in GPSDump. Your screen should like this Figure 10.4.
70
Page 72
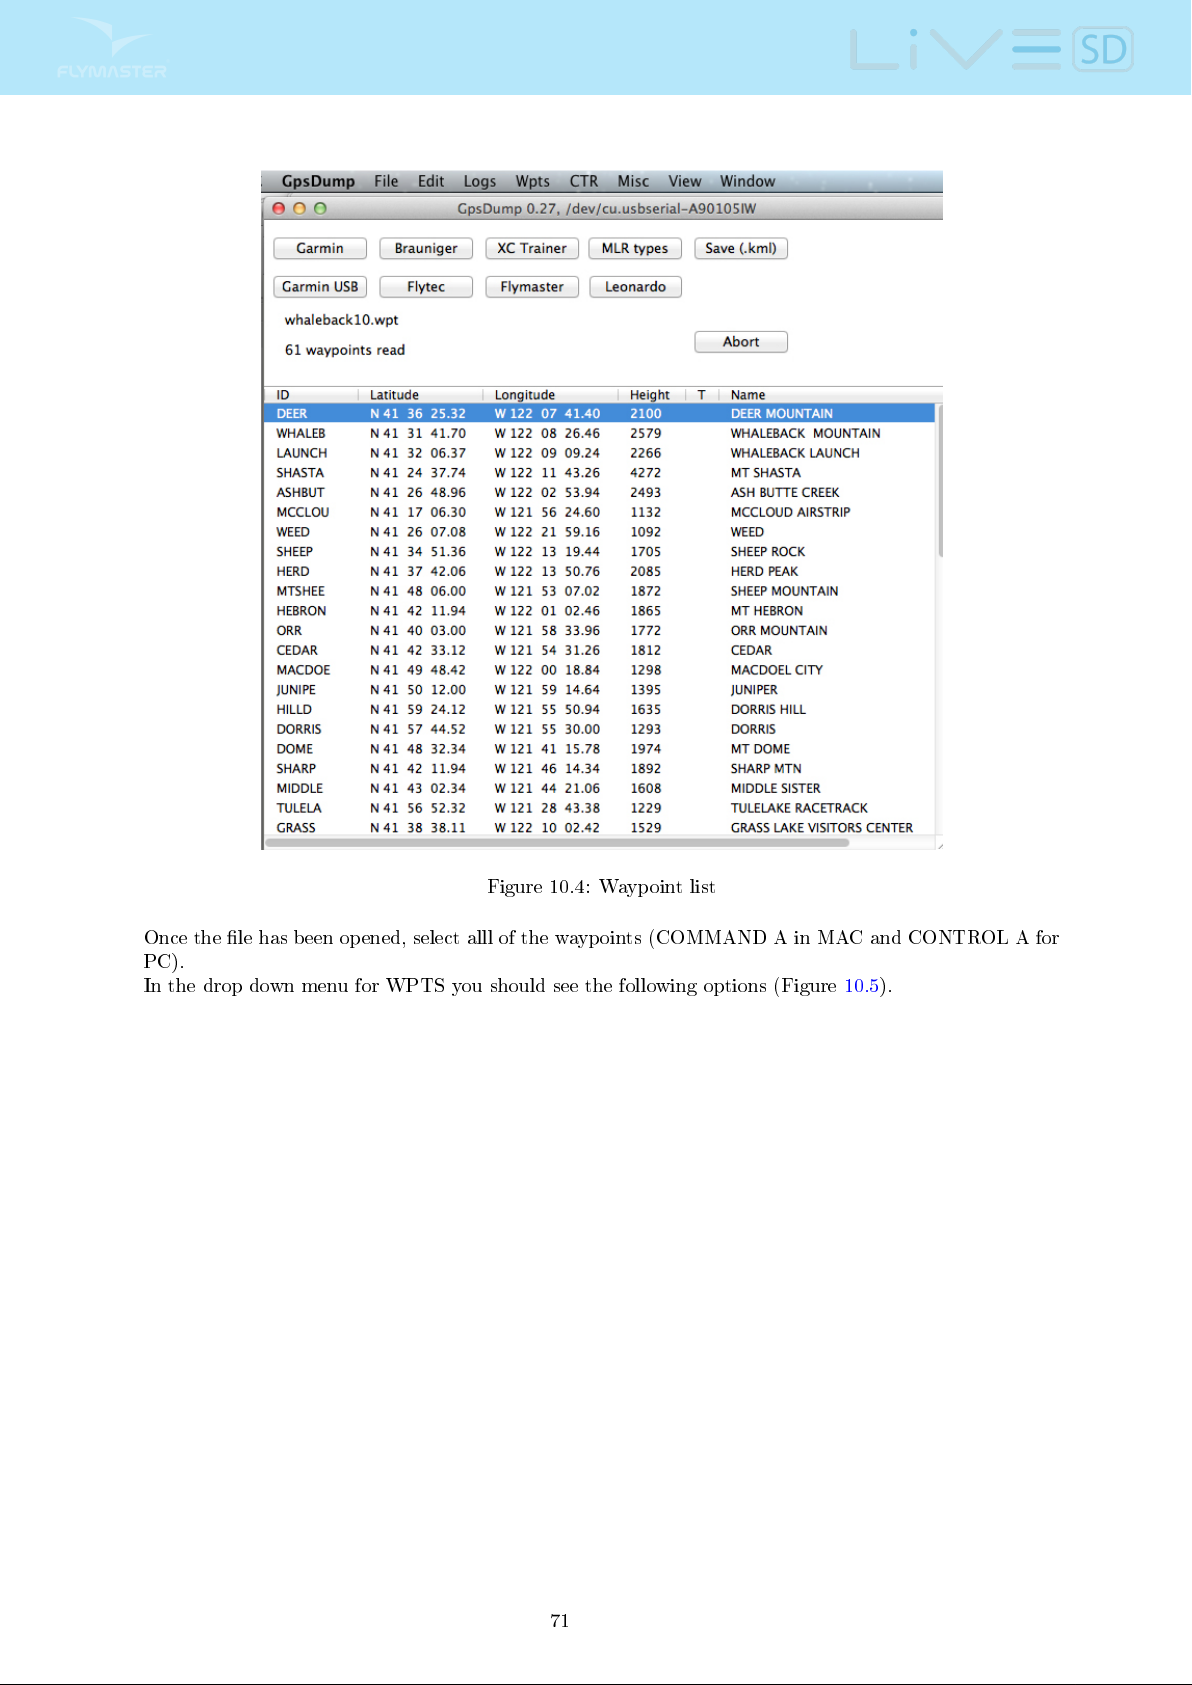
Figure 10.4: Waypoint list
Once the le has been opened, select alll of the waypoints (COMMAND A in MAC and CONTROL A for
PC).
In the drop down menu for WPTS you should see the following options (Figure 10.5).
71
Page 73
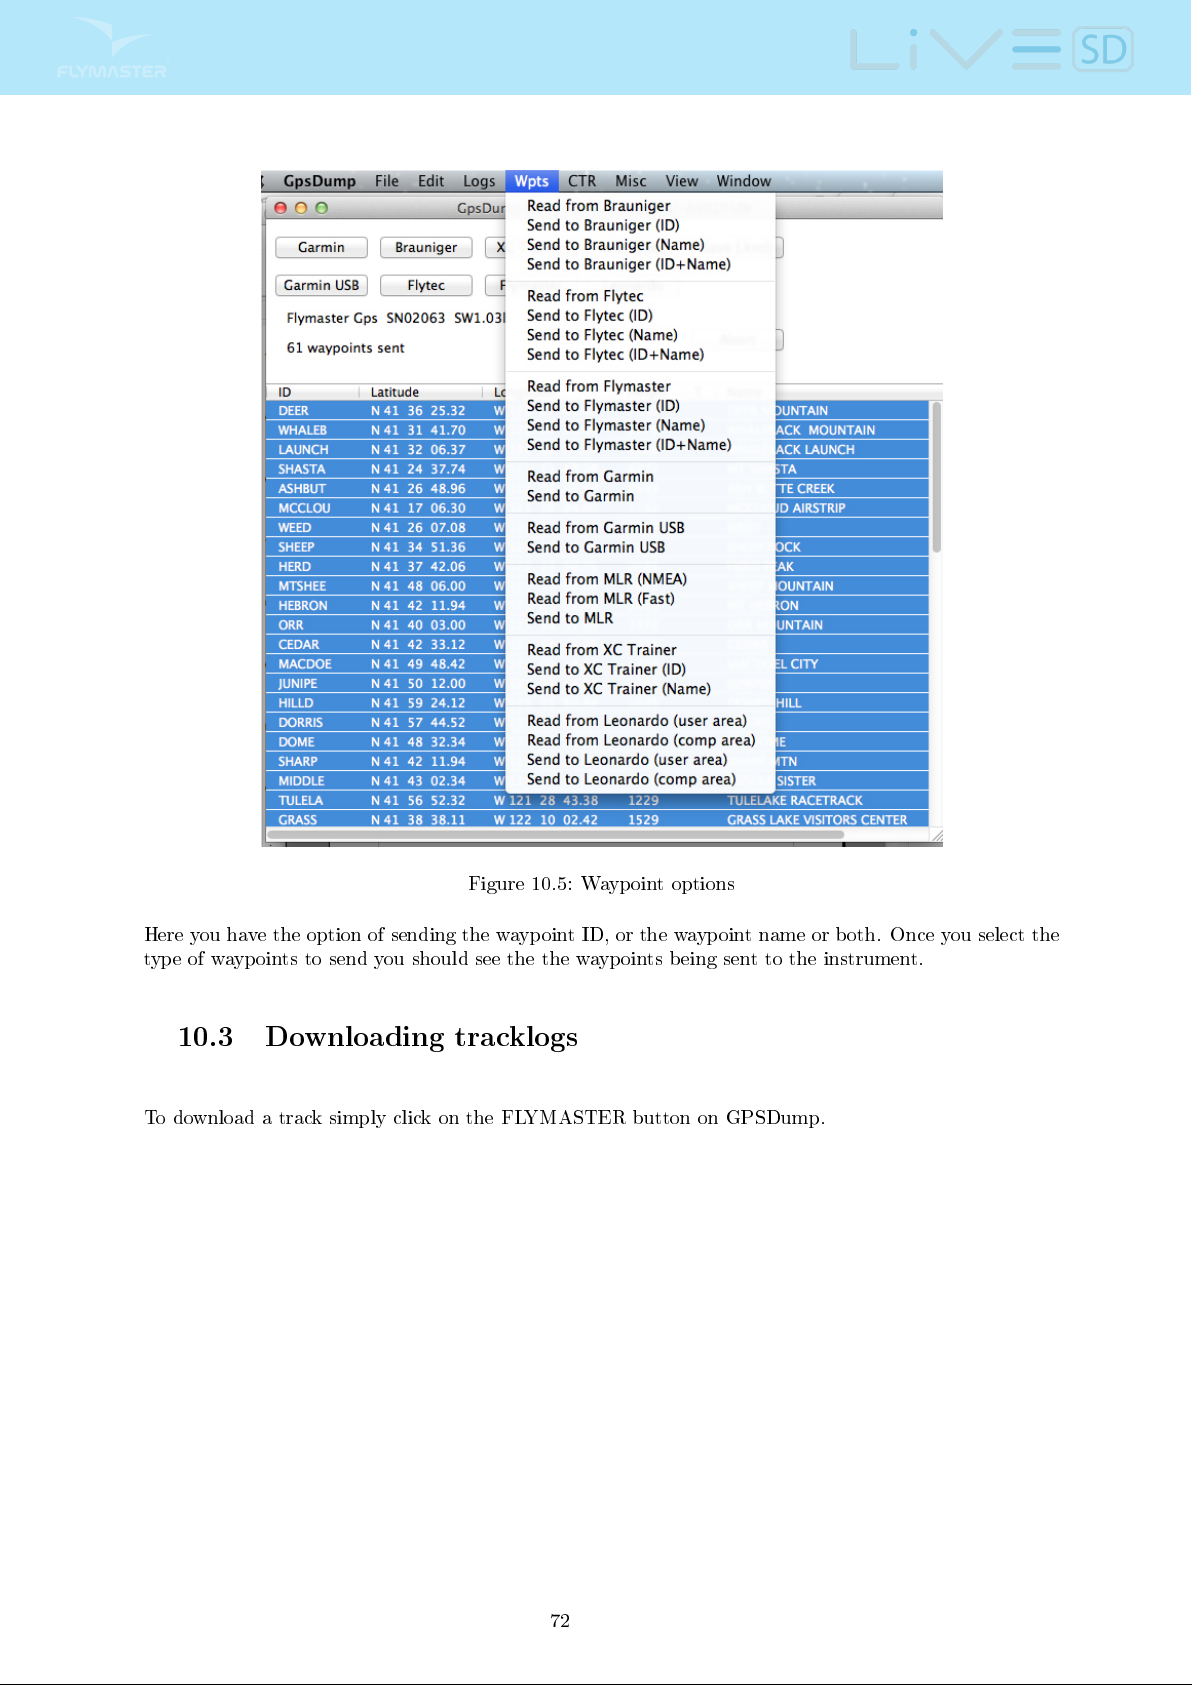
Figure 10.5: Waypoint options
Here you have the option of sending the waypoint ID, or the waypoint name or both. Once you select the
type of waypoints to send you should see the the waypoints being sent to the instrument.
10.3 Downloading tracklogs
To download a track simply click on the FLYMASTER button on GPSDump.
72
Page 74
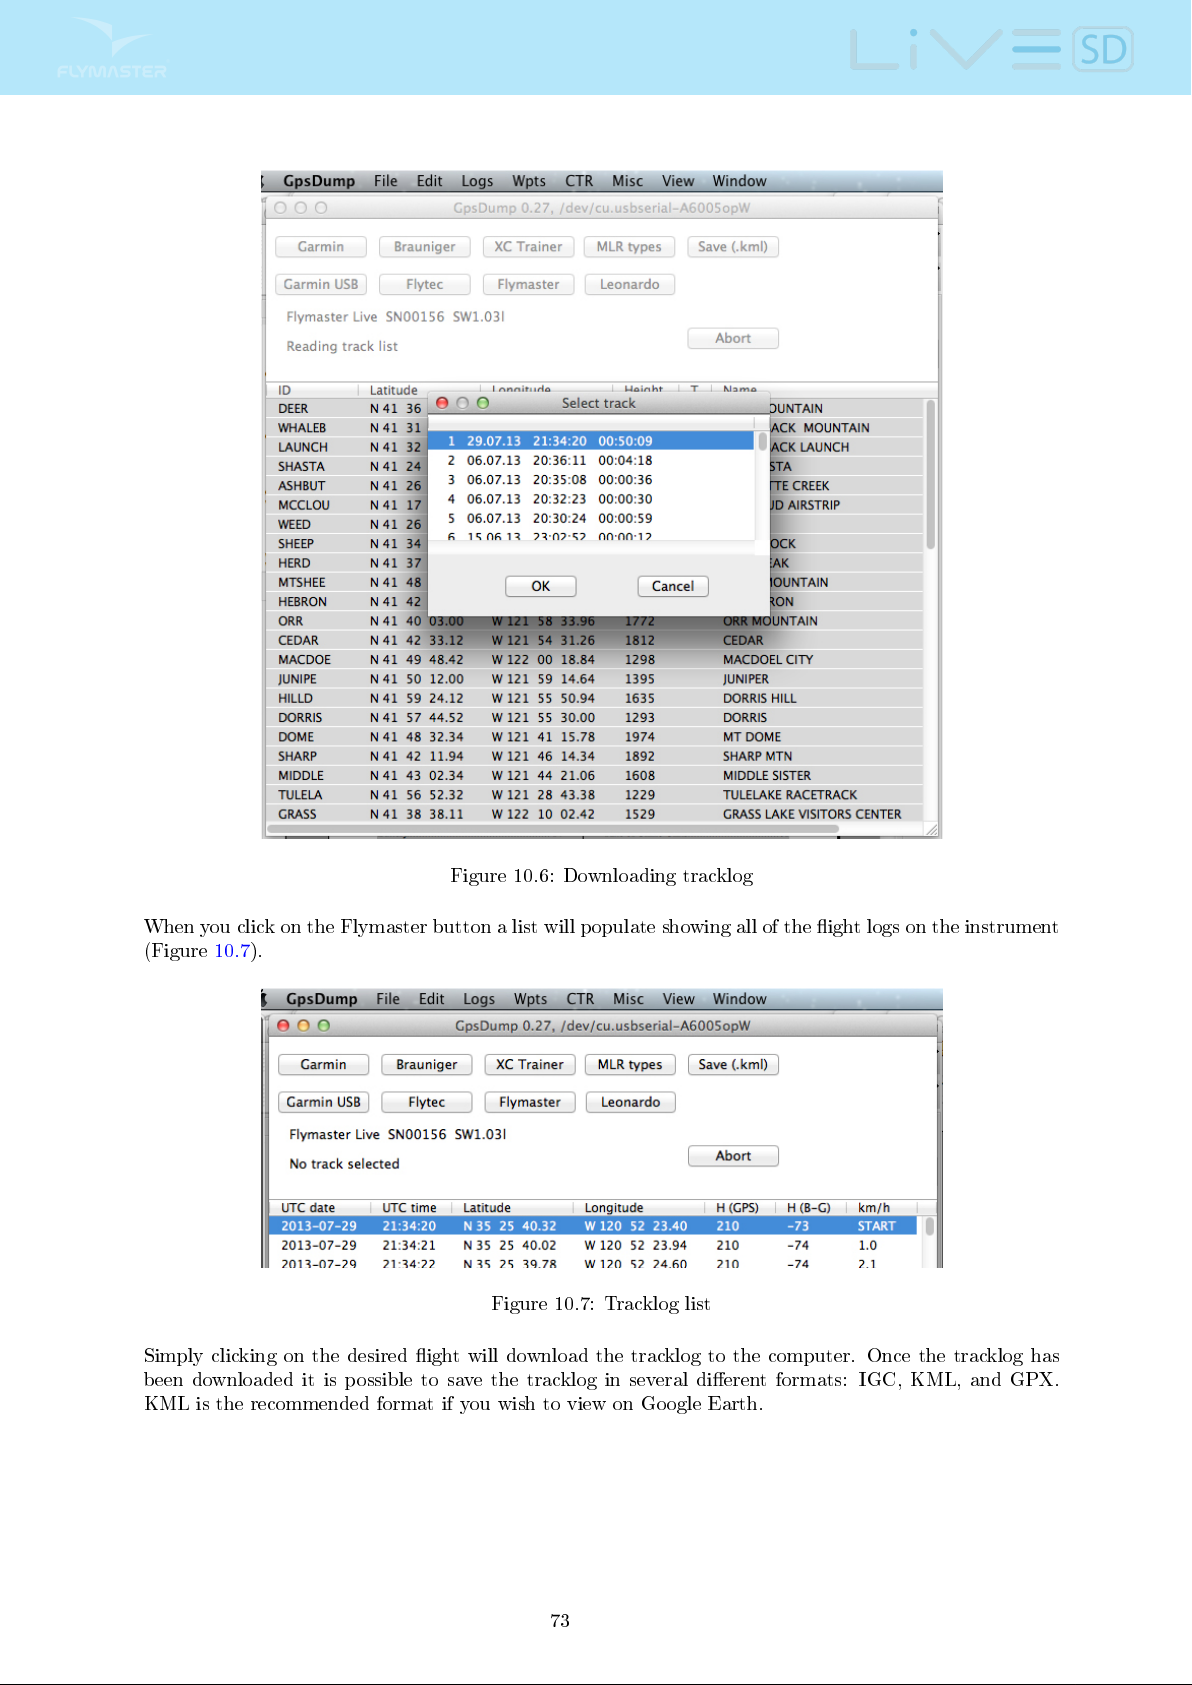
Figure 10.6: Downloading tracklog
When you click on the Flymaster button a list will populate showing all of the ight logs on the instrument
(Figure 10.7).
Figure 10.7: Tracklog list
Simply clicking on the desired ight will download the tracklog to the computer. Once the tracklog has
been downloaded it is possible to save the tracklog in several dierent formats: IGC, KML, and GPX.
KML is the recommended format if you wish to view on Google Earth.
73
Page 75
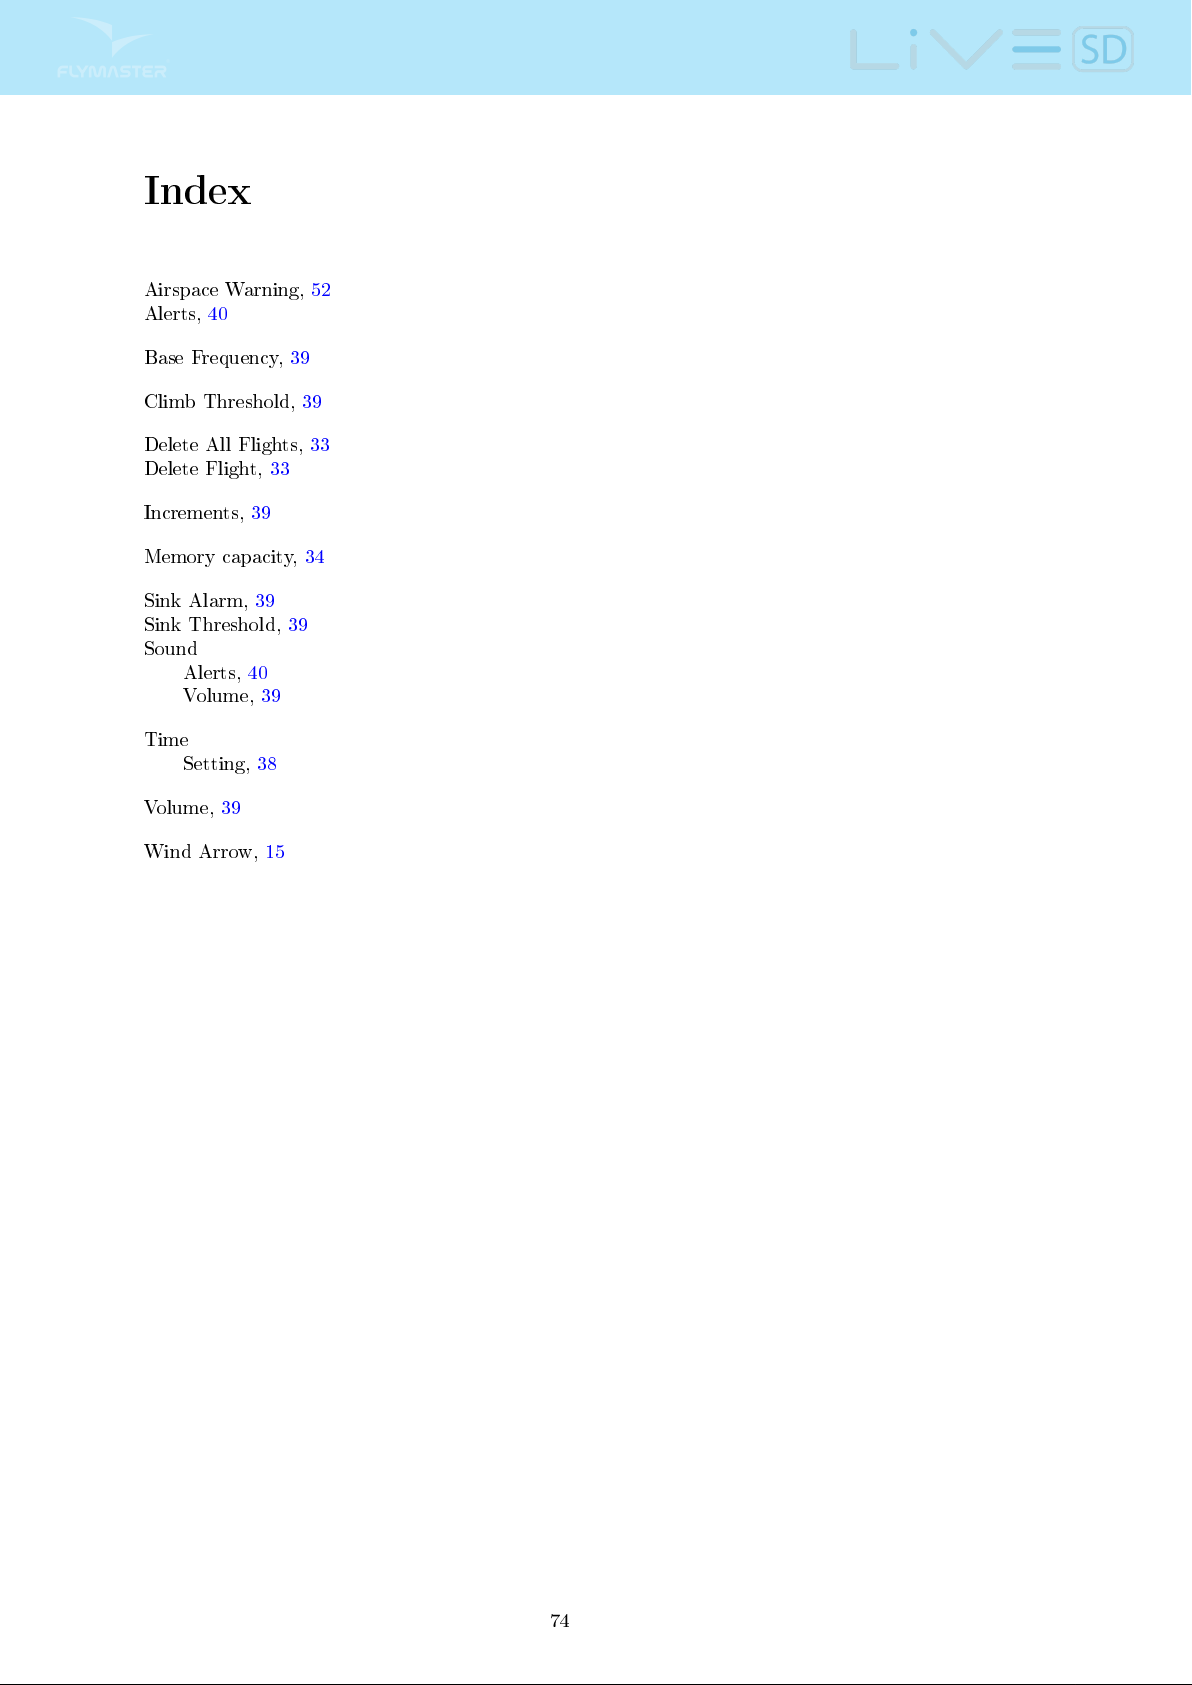
Index
Airspace Warning, 52
Alerts, 40
Base Frequency, 39
Climb Threshold, 39
Delete All Flights, 33
Delete Flight, 33
Increments, 39
Memory capacity, 34
Sink Alarm, 39
Sink Threshold, 39
Sound
Alerts, 40
Volume, 39
Time
Setting, 38
Volume, 39
Wind Arrow, 15
74
 Loading...