

Page 1
Data Sheet, V2.1, Jun. 2003
XC164CS
16-Bit Single-Chip Microcontroller
Microcontrollers
Never stop thinking.
Page 2
Edition 2003-06
Published by Infineon Technologies AG,
St.-Martin-Strasse 53,
D-81541 München, Germany
© Infineon Technologies AG 2003.
All Rights Reserved.
Attention please!
The information herein is given to describe certain components and shall not be considered as warranted
characteristics.
Terms of delivery and rights to technical change reserved.
We hereby disclaim any and all warranties, including but not limited to warranties of non-infringement, regarding
circuits, descriptions and charts stated herein.
Information
For further information on technology, delivery terms and conditions and prices please contact your nearest
Infineon Technologies Office in Germany or our Infineon Technologies Representatives worldwide (see address
list).
Warnings
Due to technical requirements components may contain dangerous substances. For information on the types in
question please contact your nearest Infineon Technologies Office.
Infineon Technologies Components may only be used in life-support devices or systems with the express written
approv al of Infine on T ec hnologies , if a failu re of such co mponents ca n reasonab ly be exp ected to cause the f ailu re
of that lif e-s upport device or sys tem, or to affect the sa f ety or ef f ec tiveness of that device or sy ste m. Life support
devices or systems are intended to be implanted in the human body, or to support and/or maintain and sustain
and/or protect human life. If they fail, it is reasonable to assume that the health of the user or other persons may
be endangered.
Page 3
Data Sheet, V2.1, Jun. 2003
XC164CS
16-Bit Single-Chip Microcontroller
Microcontrollers
Never stop thinking.
Page 4

XC164
Revision History: 2003-06 V2.1
Previous Version: 2003-01 V2.0
2002-03 V1.0
Page Subjects (major changes since last revision)
1 AD conversion times updated
6, 45 RSTIN note added
45 Digital supply voltage range for IO pads improved
48 Note 2 added
49ff Specification of Sleep and Power-down mode supply current improved
53 Conversion time formulas improved
54 Note 4 changed
55 Converter timing example improved
58 Note 1 added
63 Table 19 changed
Controller Area Network (CAN): License of Robert Bosch GmbH
We Listen to Your Comments
Any information within this document that you feel is wrong, unclear or missing at all?
Your feedback will help us to continuously improve the quality of this document.
Please send your proposal (including a reference to this document) to:
Page 5
XC16416-Bit Single-Chip Microcontroller
XC166 Family
XC164
1 Summary of Features
• High Performance 16-bit CPU with 5-Stage Pipeline
– 25 ns Instruction Cycle Time at 40 MHz CPU Clock (Single-Cycle Execution)
– 1-Cycle Multiplication (16 × 16 bit), Background Division (32 / 16 bit) in 21 Cycles
– 1-Cycle Multiply-and-Accumulate (MAC) Instructions
– Enhanced Boolean Bit Manipulation Facilities
– Zero-Cycle Jump Execution
– Additional Instructions to Support HLL and Operating Systems
– Register-Based Design with Multiple Variable Register Banks
– Fast Context Switching Support with Two Additional Local Register Banks
– 16 Mbytes Total Linear Address Space for Code and Data
– 1024 Bytes On-Chip Special Function Register Area (C166 Family Compatible)
• 16-Priority-Level Interr upt S ystem with u p to 75 Sources, Sample- Rate down to 50 ns
• 8-Channel Interrupt-Driven Single-Cycle Data Transfer Facilities via
Peripheral Event Controller (PEC), 24-Bit Pointers Cover Total Address Space
• Clock Generation via on-chip PLL (factors 1:0.15 … 1:10), or
via Prescaler (factors 1:1 … 60:1)
• On-Chip Memory Modules
– 2 Kbytes On-Chip Dual-Port RAM (DPRAM)
– 2 Kbytes On-Chip Data SRAM (DSRAM)
– 2 Kbytes On-Chip Program/Data SRAM (PSRAM)
– 128 Kbytes On-Chip Program Memory (Flash Memory or Mask ROM)
• On-Chip Peripheral Modules
– 14-Channel A/D Converter with Programmable Resolution (10-bit or 8-bit) and
Conversion Time (down to 2.55 µs or 2.15 µs)
– Two 16-Channel General Purpose Capture/Compare Units (12 Input/Output Pins)
– Capture/Compare Unit for flexible PWM Signal Generation (CAPCOM6)
(3/6 Capture/Compare Channels and 1 Compare Channel)
– Multi-Functional General Purpose Timer Unit with 5 Timers
– Two Synchronous/Asynchronous Serial Channels (USARTs)
– Two High-Speed-Synchronous Serial Channels
– On-Chip TwinCAN Interface (Rev. 2.0B active) with 32 Message Objects
(Full CAN/Basic CAN) on Two CAN Nodes, and Gateway Functionality
– On-Chip Real Time Clock
• Idle, Sleep, and Power Down Modes with Flexible Power Management
• Programmable Watchdog Timer and Oscillator Watchdog
Data Sheet 1 V2.1, 2003-06
Page 6
XC164
Derivatives
• Up to 12 Mbytes External Address Space for Code and Data
– Programmable External Bus Characteristics for Different Address Ranges
– Multiplexed or Demultiplexed External Address/Data Buses
– Selectable Address Bus Width
– 16-Bit or 8-Bit Data Bus Width
– Four Programmable Chip-Select Signals
• Up to 79 General Purpose I/O Lines,
partly with Selectable Input Thresholds and Hysteresis
• On-Chip Bootstrap Loader
• Supported by a Large Range of Development Tools like C-Compilers,
Macro-Assembler Packages, Emulators, Evaluation Boards, HLL-Debuggers,
Simulators, Logic Analyzer Disassemblers, Programming Boards
• On-Chip Debug Support via JTAG Interface
• 100-Pin TQFP Package, 0.5 mm (19.7 mil) pitch
Ordering Information
The ordering code for Infineon microcontrollers provides an exact reference to the
required product. This ordering code identifies:
Summary of Features
• the derivative itself, i.e. its function set, the temper ature range, and the supp ly voltage
• the package and the type of delivery.
For the available ordering codes for the XC164 please refer to the “Product Catalog
Microcontrollers”, which summarizes all available microcontroller variants.
Note: The ordering codes for Mask-ROM versions are defined for each product after
verification of the respective ROM code.
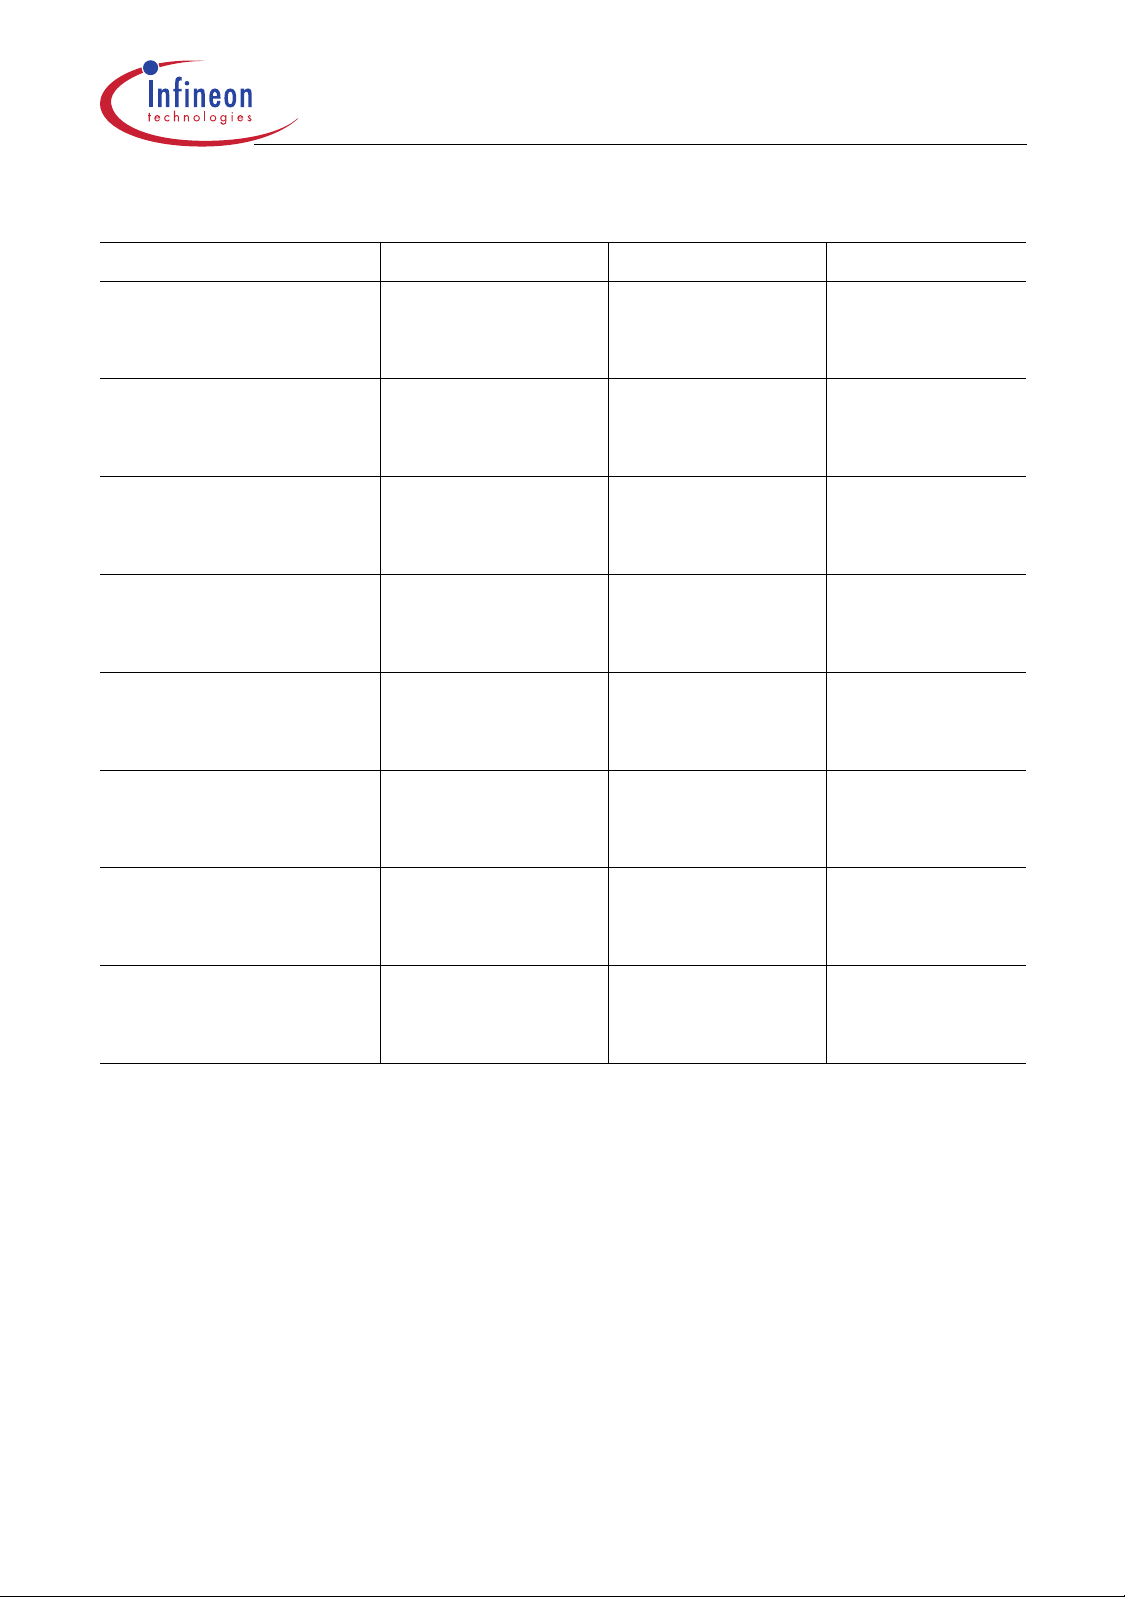
This document describes several derivatives of the XC164 group. Table 1 enumerates
these derivatives and summ arizes the differences. As this document r efers to all of these
derivatives, some descriptions may not apply to a specific product.
For simplicity all versions are referred to by the term XC164 throughout this document.
Data Sheet 2 V2.1, 2003-06
Page 7
XC164
Derivatives
Table 1 XC164 Derivative Synopsis
Derivative
SAK-XC164CS-16F40F,
1)
Program Memory On-Chip RAM Interfaces
128 Kbytes Flash 2 Kbytes DPRAM,
SAK-XC164CS-16F20F
SAK-XC164CS-16R40F,
128 Kbytes ROM 2 Kbytes DPRAM,
SAK-XC164CS-16R20F
SAF-XC164CS-16F40F,
128 Kbytes Flash 2 Kbytes DPRAM,
SAF-XC164CS-16F20F
SAF-XC164CS-16R40F,
128 Kbytes ROM 2 Kbytes DPRAM,
SAF-XC164CS-16R20F
SAK-XC164CS-8F40F,
64 Kbytes Flash 2 Kbytes DPRAM,
SAK-XC164CS-8F20F
Summary of Features
2 Kbytes DSRAM,
2 Kbytes PSRAM
2 Kbytes DSRAM,
2 Kbytes PSRAM
2 Kbytes DSRAM,
2 Kbytes PSRAM
2 Kbytes DSRAM,
2 Kbytes PSRAM
2 Kbytes DSRAM,
2 Kbytes PSRAM
ASC0, ASC1,
SSC0, SSC1,
CAN0, CAN1
ASC0, ASC1,
SSC0, SSC1,
CAN0, CAN1
ASC0, ASC1,
SSC0, SSC1,
CAN0, CAN1
ASC0, ASC1,
SSC0, SSC1,
CAN0, CAN1
ASC0, ASC1,
SSC0, SSC1,
CAN0, CAN1
SAK-XC164CS-8R40F,
SAK-XC164CS-8R20F
SAF-XC164CS-8F40F,
SAF-XC164CS-8F20F
SAF-XC164CS-8R40F,
SAF-XC164CS-8R20F
1)
This Data Sheet i s vali d for de vices starting with a nd incl uding de sign st ep AD of th e Flash v ersion , and design
step AA of the ROM version.
64 Kbytes ROM 2 Kbytes DPRAM,
2 Kbytes DSRAM,
2 Kbytes PSRAM
64 Kbytes Flash 2 Kbytes DPRAM,
2 Kbytes DSRAM,
2 Kbytes PSRAM
64 Kbytes ROM 2 Kbytes DPRAM,
2 Kbytes DSRAM,
2 Kbytes PSRAM
ASC0, ASC1,
SSC0, SSC1,
CAN0, CAN1
ASC0, ASC1,
SSC0, SSC1,
CAN0, CAN1
ASC0, ASC1,
SSC0, SSC1,
CAN0, CAN1
Data Sheet 3 V2.1, 2003-06
Page 8
XC164
Derivatives
General Device Information
2 General Device Informati o n
2.1 Introduction
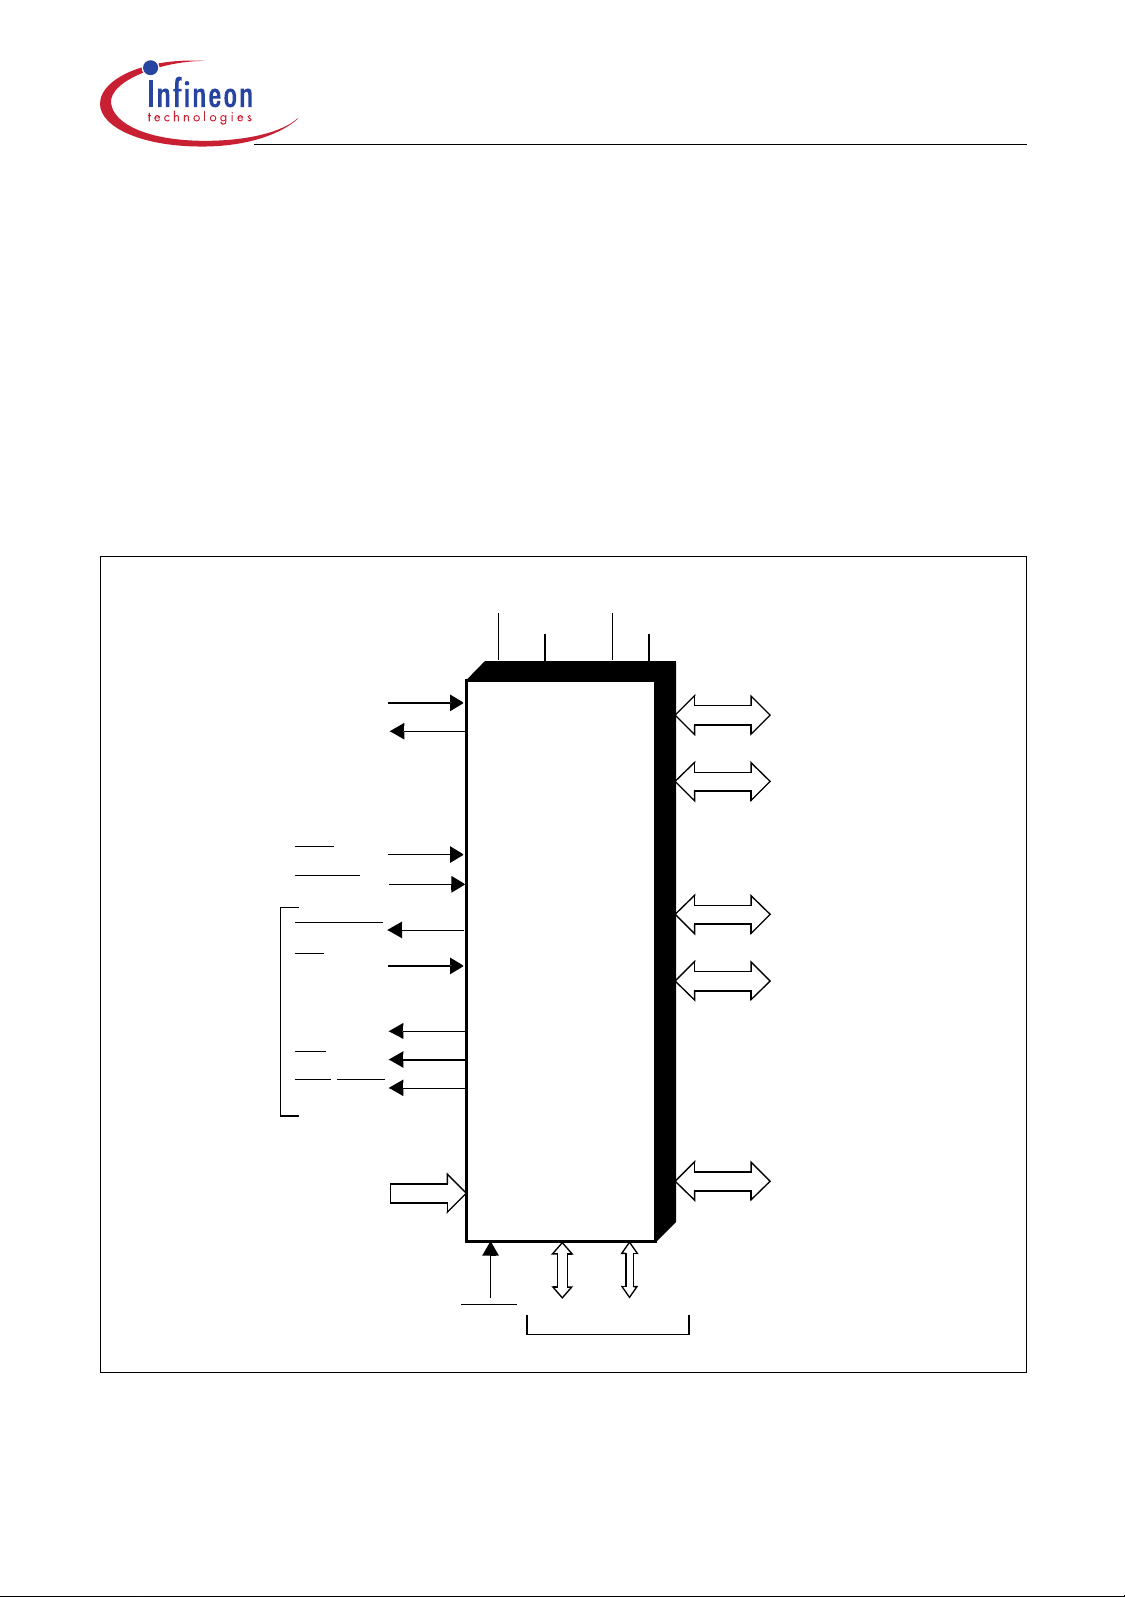
The XC164 derivatives are high-performance m embers of the Infineon X C166 Family of
full featured single-chip CMOS microcontrollers. These devices extend the functionality
and performan ce of the C166 Family in terms of instructions (MA C unit), periphe rals, and
speed. They combine high CPU performance (up to 40 million instructions per second)
with high peripheral functionality and enhanced IO-capabilities. They also provide clock
generation via PLL and various on-chip memory modules such as program ROM or
Flash, program RAM, and data RAM.
AGND
V
DDI/P
V
SSI/P
PORT0
16 bit
XTAL1
XTAL2
V
AREF
V
Port 20
5 bit
NMI
RSTIN
RSTOUT
EA
ALE
RD
WR/WRL
Port 5
14 bit
XC164
TRST JTAG Debug
PORT1
16 bit
Port 3
14 bit
Port 4
8 bit
Port 9
6 bit
Via Port 3
Figure 1 Logi c Symbol
Data Sheet 4 V2.1, 2003-06
Page 9
XC164
Derivatives
General Device Information
2.2 Pin Configuration and Definition
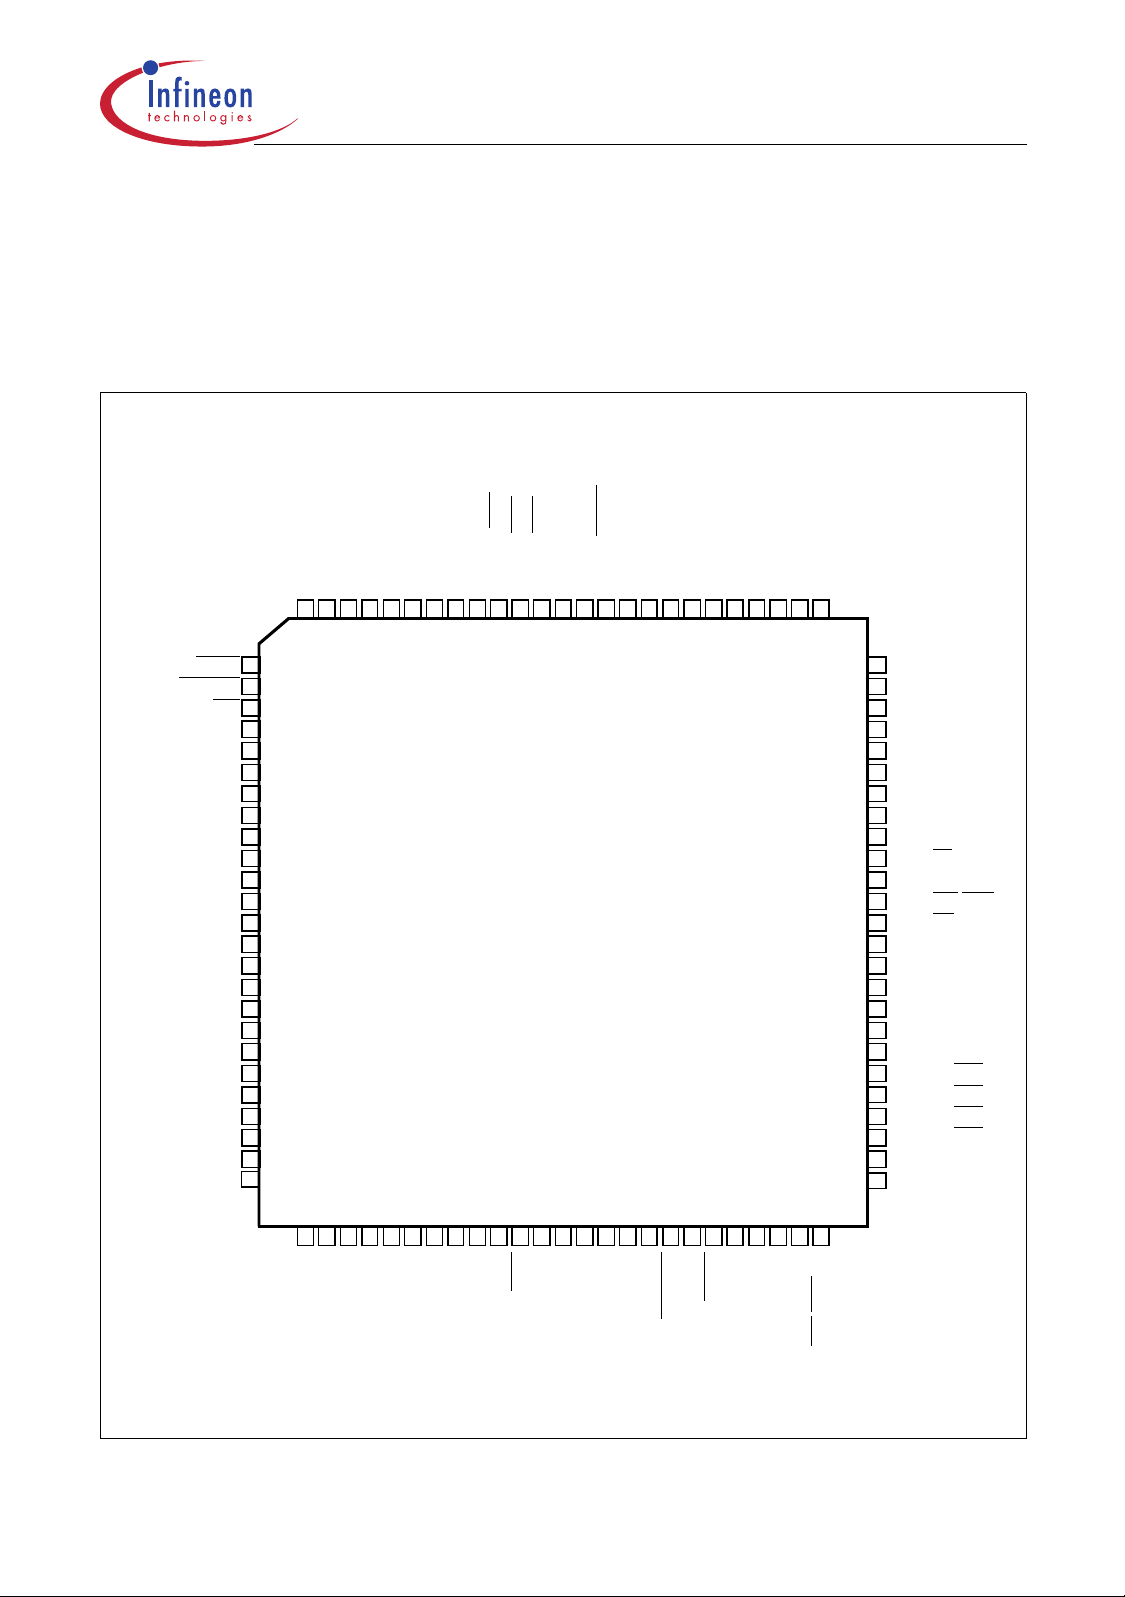
The pins of the XC164 are described in detail in Table 2, including all their alternate
functions. Figure 2 summarizes all pins in a condensed way, showing their location on
the 4 sides of the package. E*) and C*) mark pins to be used as alternate external
interrupt inputs, C*) marks pins that can have CAN interface lines assigned to them.
/MTSR1/EX2IN
/CC23/EX0I N
RSTIN
P20.12/RSTOUT
NMI
P0H.0/ AD8
P0H.1/ AD9
P0H.2/AD10
P0H.3/AD11
V
SSP
V
P9.0/CC16IO/C*)
P9.1/CC17IO/C*)
P9.2/CC18IO/C*)
P9.3/CC19IO/C*)
P9.4/CC20I O
P9.5/CC21I O
P5.10/AN10/T6EUD
P5.11/AN11/T5EUD
DDP
V
SSP
V
DDP
P5.0/AN0
P5.1/AN1
P5.2/AN2
P5.3/AN3
P5.4/AN4
P5.5/AN5
6P1/MRST1/ EX1I N
SSIVDDI
XTAL1
XTAL2
V
P1H.7/A15/CC27/EX7IN
P1H.6/A14/CC26/EX6IN
P1H.5/A13/CC25/EX5IN
P1H.4/A12/CC24/EX4IN
P1H.3/A11/T7IN/SCLK1/EX3IN/E*)
100999897969594939291908988878685848382818079787776
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
P1H.0/A8/C6P0
P1H.2/A10/C6P2
P1H.1/A9/C
XC164
SSPVDDP
V
TRAP/CC22
C
P1L.6/A6/COUT63
P1L.5/A5/COUT62
P1L.4/A4/CC62
P1L.3/A3/COUT61
P1L.2/A2/CC61
P1L.1/A1/COUT60
P1L.0/A0/CC60
P0H.7/AD15
P0H.6/AD14
P1L.7/A7/
P0H.5/AD13
75
P0H.4/ AD1 2
74
P0L.7/A D7
73
P0L.6/A D6
72
P0L.5/A D5
71
P0L.4/A D4
70
P0L.3/A D3
69
P0L.2/A D2
68
P0L.1/A D1
67
P0L.0/A D0
66
P20.5/E A
65
P20.4/A LE
64
P20.1/WR
63
P20.0/R D
62
V
61
V
60
P4.7/A23 /C*)
59
P4.6/A22 /C*)
58
P4.5/A21/C*)
57
P4.4/A20/C*)
56
P4.3/A19 /CS0
55
P4.2/A18 /CS1
54
P4.1/A17 /CS2
53
P4.0/A16 /CS3
52
P3.15/C LKOUT /FO
51
P3.13/SCLK0/E*)
/WRL
SSP
DDP
26272829303132333435363738394041424344454647484950
SSI
DDI
SSP
TRST
DDP
V
V
P3.6/T3I N
P3.8/MRST0
P3.9/MTS R0
P3.2/CAP IN/TD I
P3.3/T3OUT/TDO
P3.4/T3EUD/TMS
P3.1/T6OUT/ RxD 1/TC K/ E* )
P3.7/T2IN/BRKIN
P3.5/ T4 I N/TxD1/BRKOUT
/WRH/E*)
P3.10/TxD0/E*)
P3.11/RxD0/E*)
P3.12/BHE
V
AREF
AGND
V
P5.6/AN6
V
P5.7/AN7
P5.12/AN12/T6IN
P5.13/AN13/T5IN
P5.14/AN14/T4EUD
V
P5.15/AN15/T2EUD
Figure 2 Pin Configuration (top view)
Data Sheet 5 V2.1, 2003-06
Page 10
XC164
Derivatives
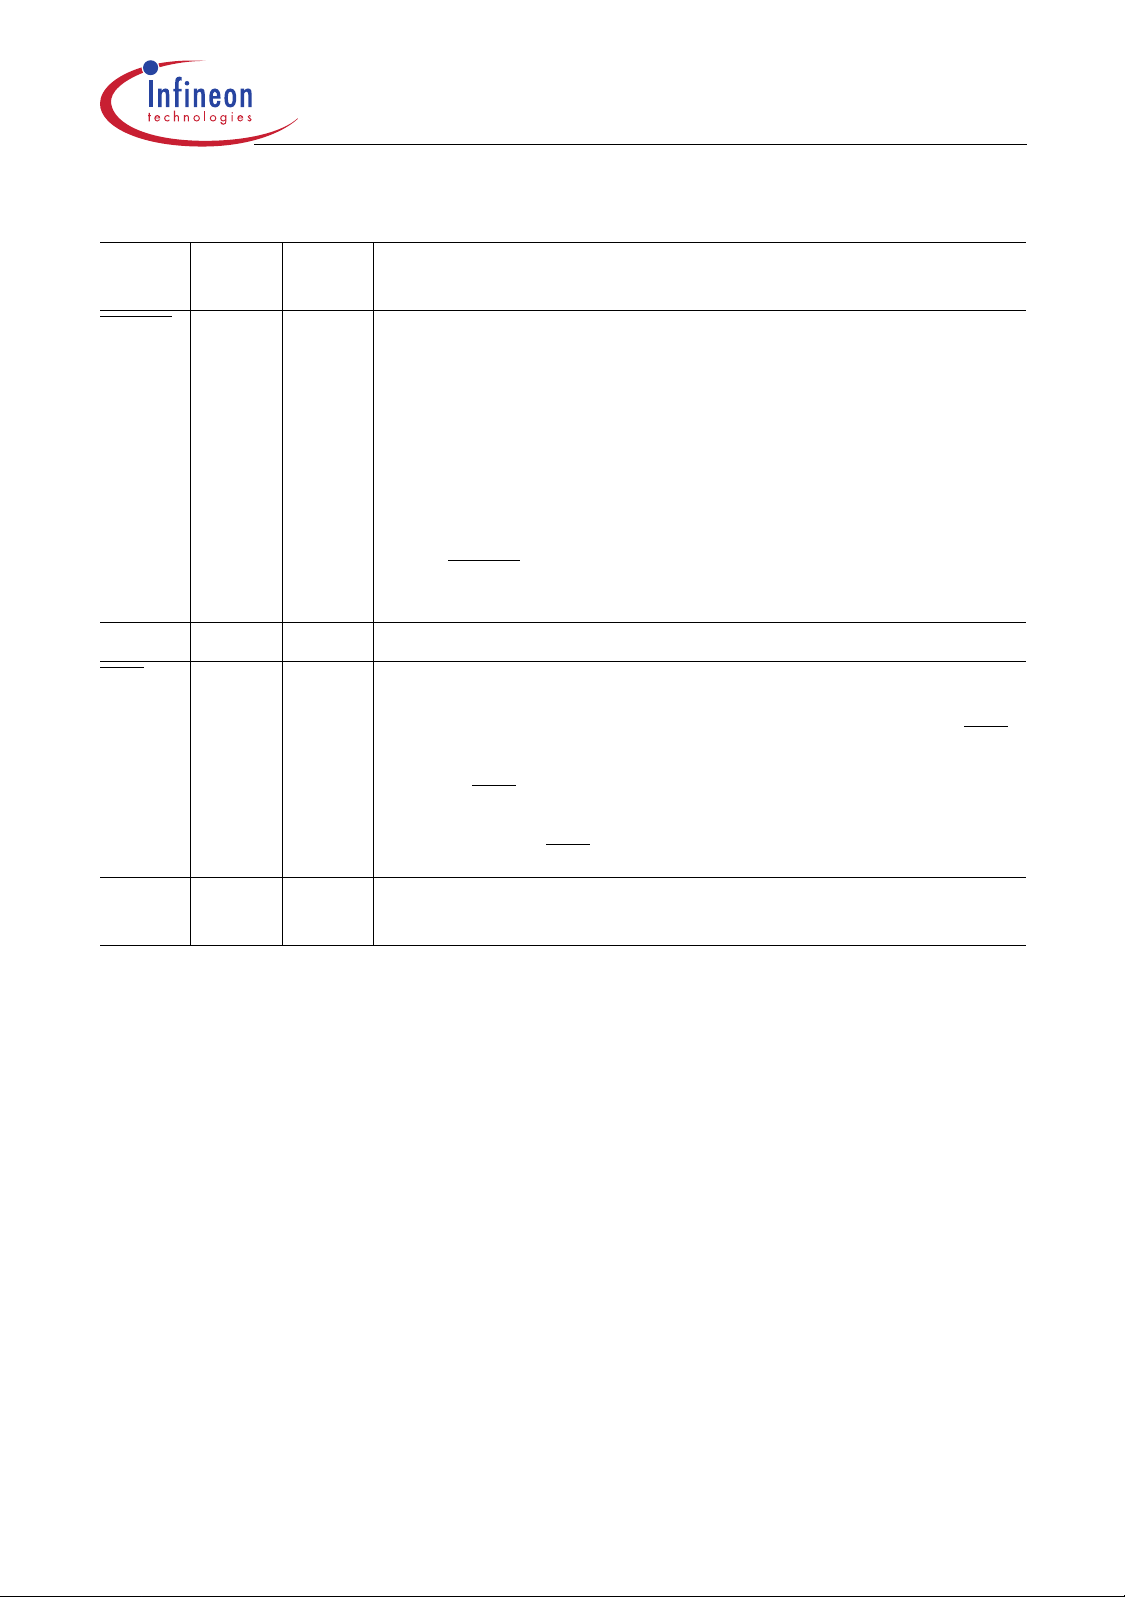
Table 2 Pin Definitions and Functions
Symbol Pin
Num.
RSTIN 1 I Reset Input with Schmitt-Trigger characteristics. A low level
Input
Outp.
Function
at this pin while the oscillator is running resets the XC164.
A spike filter suppresses input pulses <10 ns. Input pulses
>100 ns safely pass the filter. The minimum duration for a
safe recognition should be 100 ns + 2 CPU clock cycles.
General Device Information
Note: The reset duration must be sufficient to let the
hardware configuration signals settle.
External circuitry must guarantee low level at the
RSTIN pin at least until both power supply voltages
have reached the operating range.
P20.12 2 IO For details, please refer to the description of P20.
NMI 3 I Non-Maskable Interrupt Input. A high to low transition at this
pin causes the CPU to vector to the NMI trap routine. When
the PWRDN (power down) instruction is executed , the NM I
pin must be low i n order to force the XC164 into power down
mode. If NMI is high, when PWRDN is executed, the part will
continue to run in normal mode.
If not used, pin NMI should be pulled high externally.
P0H.0P0H.3
4…7 IO For details, please refer to the description of PORT0.
Data Sheet 6 V2.1, 2003-06
Page 11
XC164
Derivatives
Table 2 Pin Definitions and Functions (cont’d)
Symbol Pin
Num.
P9
Input
Outp.
IO
Function
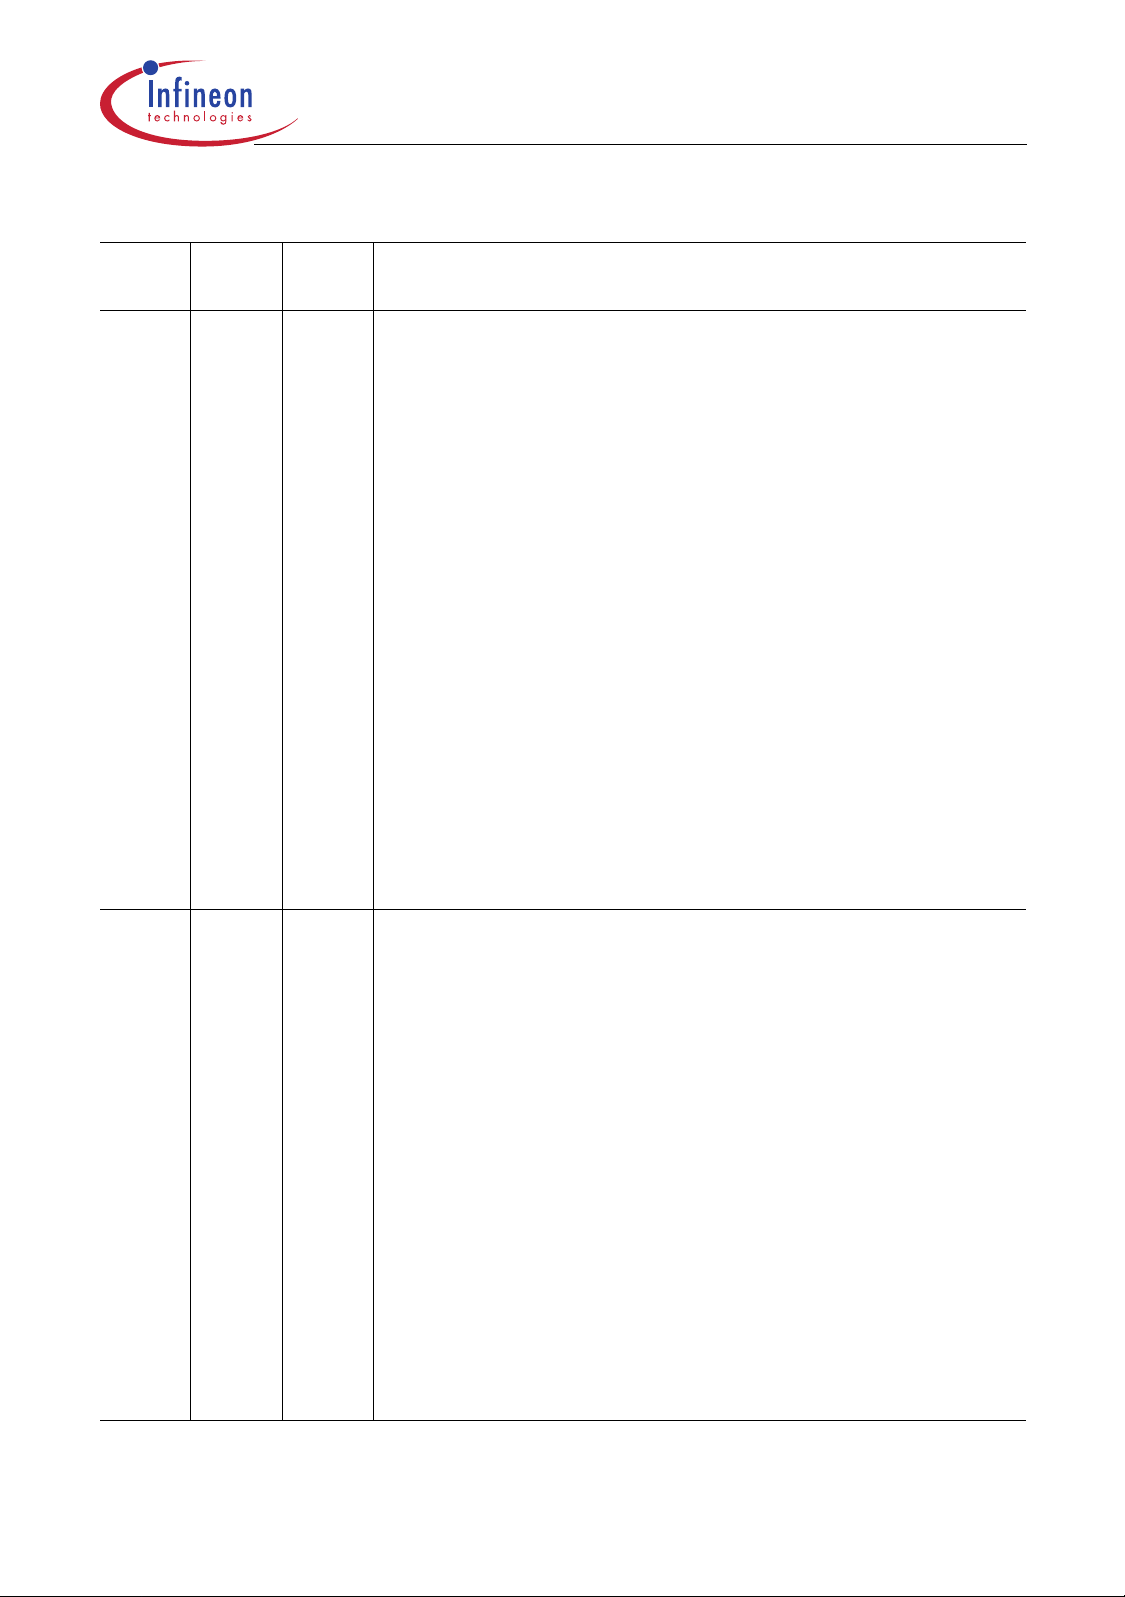
Port 9 is a 6-bit bidirectional I/O port. Each pin can be
programmed for input (output driver in high-impedance
state) or output (configurable as push/pull or open drain
driver). The input threshold of Port 9 is selectable (standard
or special).
The following Port 9 pins also serve for alternate functions:
P9.0
P9.1
P9.2
P9.3
P9.4
P9.5
10
11
12
13
14
15
I/O
I
I
I/O
O
I
I/O
I
I
I/O
O
I
I/O
I/O
CC16IO CAPCOM2: CC16 Capture Inp./Compare Outp.,
CAN2_RxDCAN Node 2 Receive Data Input,
EX7IN Fast External Interrupt 7 Input (alternate pin B)
CC17IO CAPCOM2: CC17 Capture Inp./Compare Outp.,
CAN2_TxD CAN Node 2 Transmit Data Output,
EX6IN Fast External Interrupt 6 Input (alternate pin B)
CC18IO CAPCOM2: CC18 Capture Inp./Compare Outp.,
CAN1_RxDCAN Node 1 Receive Data Input,
EX7IN Fast External Interrupt 7 Input (alternate pin A)
CC19IO CAPCOM2: CC19 Capture Inp./Compare Outp.,
CAN1_TxD CAN Node 1 Transmit Data Output,
EX6IN Fast External Interrupt 6 Input (alternate pin A)
CC20IO CAPCOM2: CC20 Capture Inp./Compare Outp.
CC21IO CAPCOM2: CC21 Capture Inp./Compare Outp.
General Device Information
1)
P5
P5.0
P5.1
P5.2
P5.3
P5.4
P5.5
P5.10
P5.11
P5.6
P5.7
P5.12
P5.13
P5.14
P5.15
18
19
20
21
22
23
24
25
26
27
30
31
32
33
I
Port 5 is a 14-bit input-only port.
The pins of Port 5 also serve as anal og input channels for the
A/D converter, or they serve as timer inputs:
I
I
I
I
I
I
I
I
I
I
I
I
I
I
AN0
AN1
AN2
AN3
AN4
AN5
AN10, T6EUD GPT2 Timer T6 Ext. Up/Down C trl. Inp.
AN11, T5EUD GPT2 Timer T5 Ext. Up/Down C trl. Inp.
AN6
AN7
AN12, T6IN GPT2 Timer T6 Count/Gate Input
AN13, T5IN GPT2 Timer T5 Count/Gate Input
AN14, T4EUD GPT1 Timer T4 Ext. Up/Down C trl. Inp.
AN15, T2EUD GPT1 Timer T2 Ext. Up/Down C trl. Inp.
Data Sheet 7 V2.1, 2003-06
Page 12
XC164
Derivatives
Table 2 Pin Definitions and Functions (cont’d)
Symbol Pin
Num.
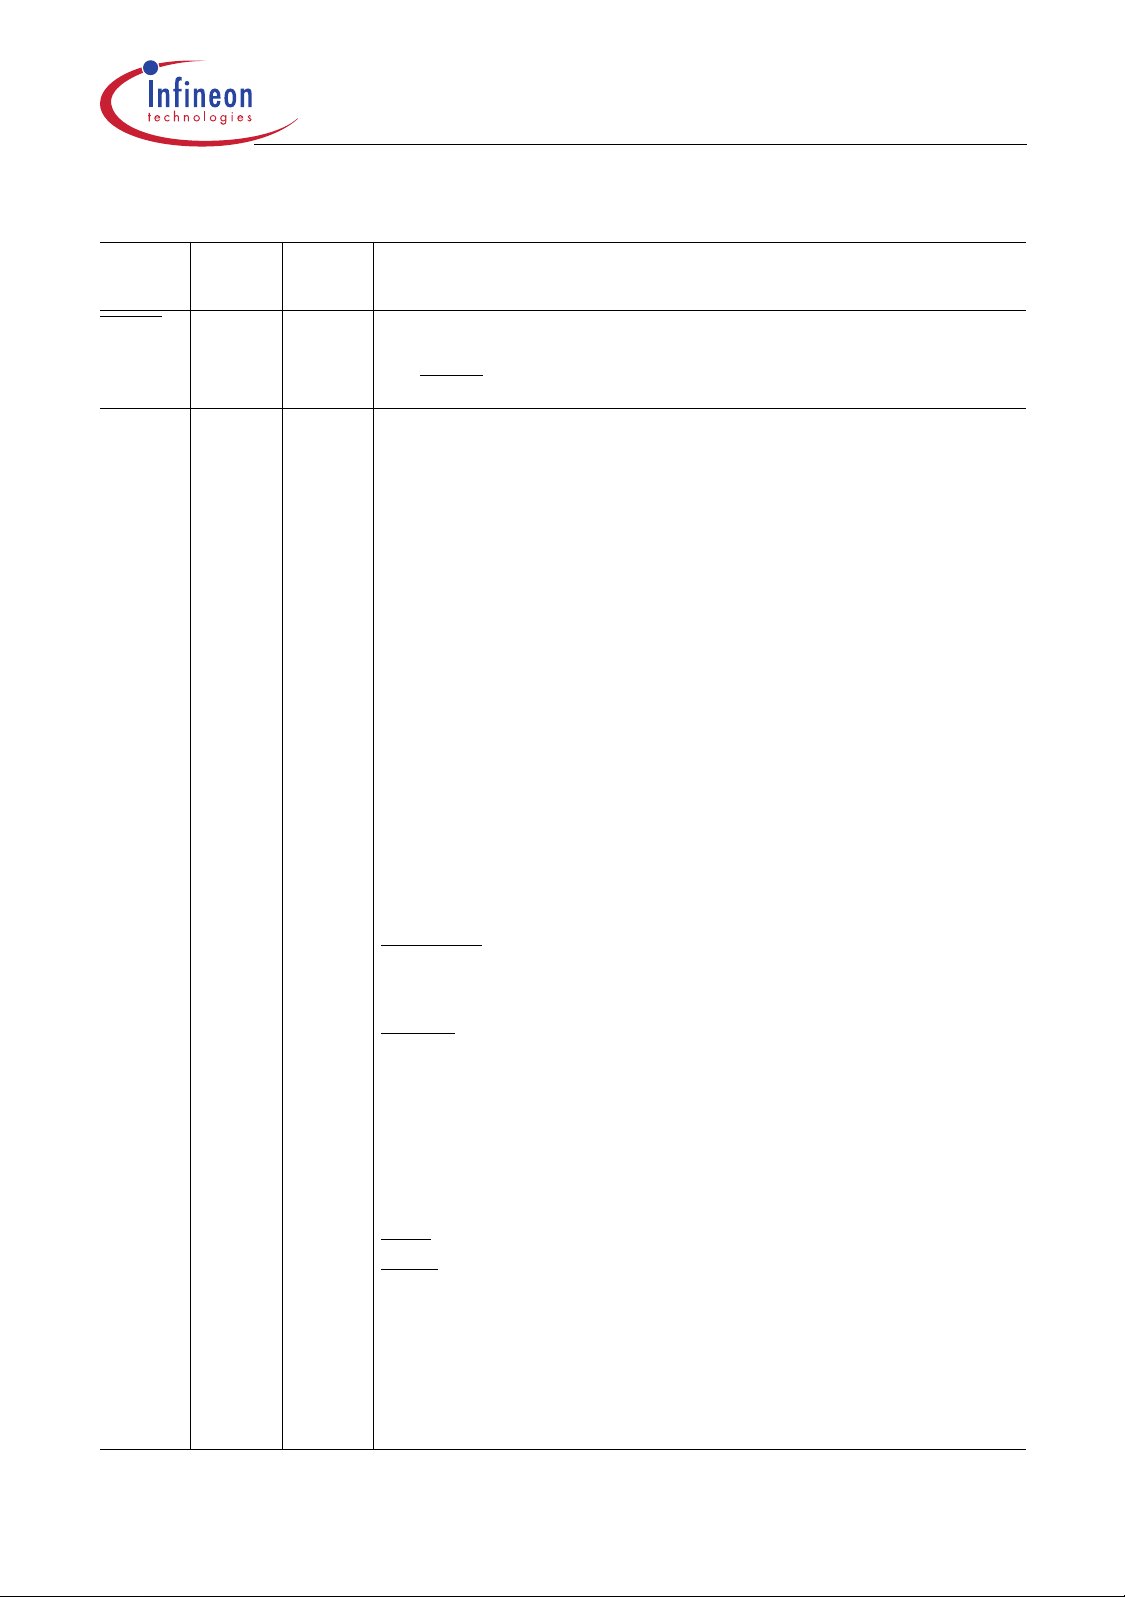
TRST 36 I Test-System Reset Input. A high level at this pin activates
P3
P3.1
P3.2
P3.3
P3.4
P3.5
P3.6
P3.7
P3.8
P3.9
P3.10
P3.11
P3.12
P3.13
P3.15
39
40
41
42
43
44
45
46
47
48
49
50
51
52
Input
Outp.
IO
O
I/O
I
I
I
I
O
O
I
I
I
O
O
I
I
I
I/O
I/O
O
I
I/O
I
O
O
I
I/O
I
O
O
Function
the XC164’s debug system. For normal system operation,
pin TRST should be held low.
Port 3 is a 14-bit bidirectional I/O port. Each pin can be
programmed for input (output driver in high-impedance
state) or output (configurable as push/pull or open drain
driver). The input threshold of Port 3 is selectable (standard
or special).
The following Port 3 pins also serve for alternate functions:
T6OUT GPT2 Timer T6 Toggle Latch Output,
RxD1 ASC1 Data Input (Async.) or Inp./Outp. (Sync.),
EX1IN Fast External Interrupt 1 Input (alternate pin A),
TCK Debug System: JTAG Clock Input
CAPIN GPT2 Register CAPREL Capture Input,
TDI Debug System: JTAG Data In
T3OUT GPT1 Timer T3 Toggle Latch Output,
TDO Debug System: JTAG Data Out
T3EUD GPT1 Timer T3 External Up/D own Control Input,
TMS Debug System: JTAG Test Mode Selection
T4IN GPT1 Timer T4 Count/Gate/Reload/Capture Inp
TxD1 ASC0 Clock/Data Output (Async./Sync.),
BRKOUT Debug System: Break Out
T3IN GPT1 Timer T3 Count/Gate Input
T2IN GPT1 Timer T2 Count/Gate/Reload/Capture Inp
BRKIN Debug System: Break In
MRST0 SSC0 Master-Receive/Slave-Transmit In/Out.
MTSR0 SSC0 Master-Transmit/Slave-Receive Out/In.
TxD0 ASC0 Clock/Data Output (Async./Sync.),
EX2IN Fast External Interrupt 2 Input (alternate pin B)
RxD0 ASC0 Data Input (Async.) or Inp./Outp. (Sync.),
EX2IN Fast External Interrupt 2 Input (alternate pin A)
BHE External Memory High Byte Enable Signal,
WRH External Memory High Byte Write Strobe,
EX3IN Fast External Interrupt 3 Input (alternate pin B)
SCLK0 SSC0 Master Clock Output / Slave Clock Input.,
EX3IN Fast External Interrupt 3 Input (alternate pin A)
CLKOUT System Clock Output (=CPU Clock),
FOUT Programmable Frequency Output
General Device Information
Data Sheet 8 V2.1, 2003-06
Page 13
XC164
Derivatives
Table 2 Pin Definitions and Functions (cont’d)
Symbol Pin
Num.
P4
Input
Outp.
IO
Function
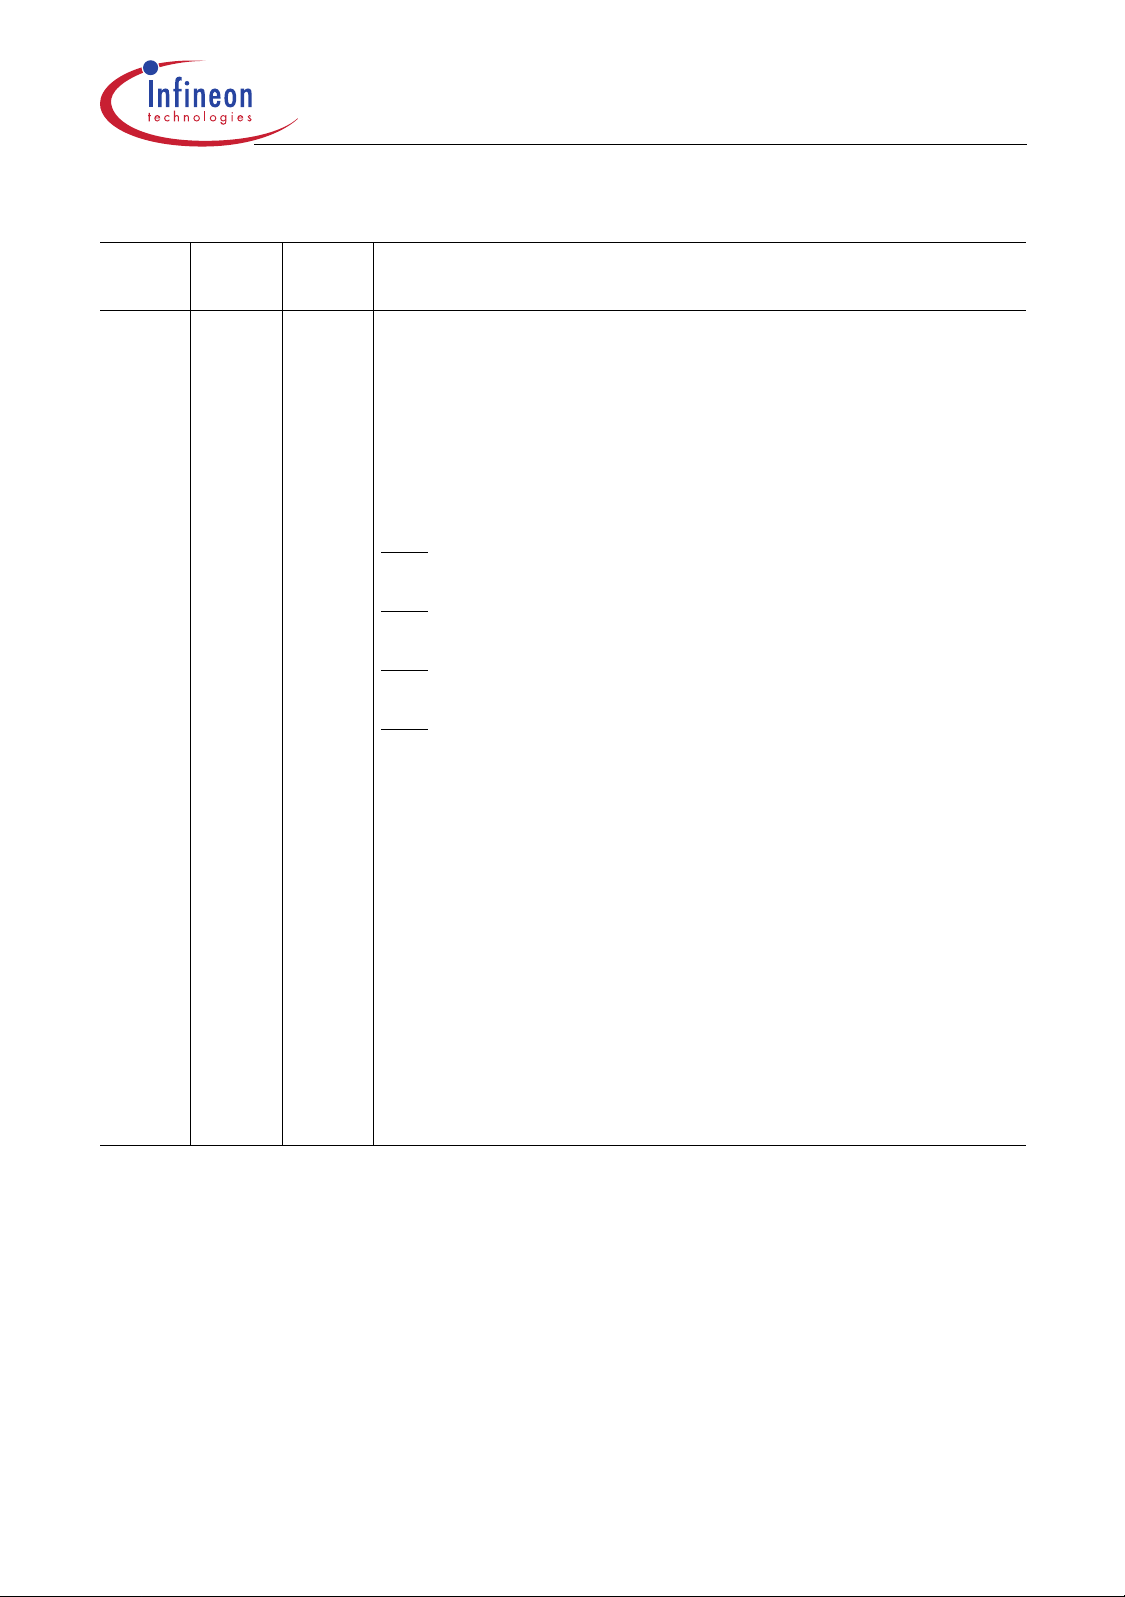
Port 4 is an 8-bit bidirectional I/O port. Each pin can be
programmed for input (output driver in high-impedance
state) or output (configurable as push/pull or open drain
driver). The input threshold of Port 4 is selectable (standard
or special).
Port 4 can be used to output the segment address lines, the
optional chip select lines, and for serial interface lines:
P4.0
P4.1
P4.2
P4.3
P4.4
P4.5
P4.6
P4.7
53
54
55
56
57
58
59
60
O
O
O
O
O
O
O
O
O
I
I
O
I
I
O
O
I
O
I
O
I
A16 Least Significant Segment Address Line,
CS3 Chip Select 3 Output
A17 Segment Address Line,
CS2 Chip Select 2 Output
A18 Segment Address Line,
CS1 Chip Select 1 Output
A19 Segment Address Line,
CS0 Chip Select 0 Output
A20 Segment Address Line,
CAN2_RxDCAN Node 2 Receive Data Input,
EX5IN Fast External Interrupt 5 Input (alternate pin B)
A21 Segment Address Line,
CAN1_RxDCAN Node 1 Receive Data Input,
EX4IN Fast External Interrupt 4 Input (alternate pin B)
A22 Segment Address Line,
CAN1_TxD CAN Node 1 Transmit Data Output,
EX5IN Fast External Interrupt 5 Input (alternate pin A)
A23 Most Significant Segment Address Line,
CAN1_RxDCAN Node 1 Receive Data Input,
CAN2_TxD CAN Node 2 Transmit Data Output,
EX4IN Fast External Interrupt 4 Input (alternate pin A)
General Device Information
1)
Data Sheet 9 V2.1, 2003-06
Page 14
XC164
Derivatives
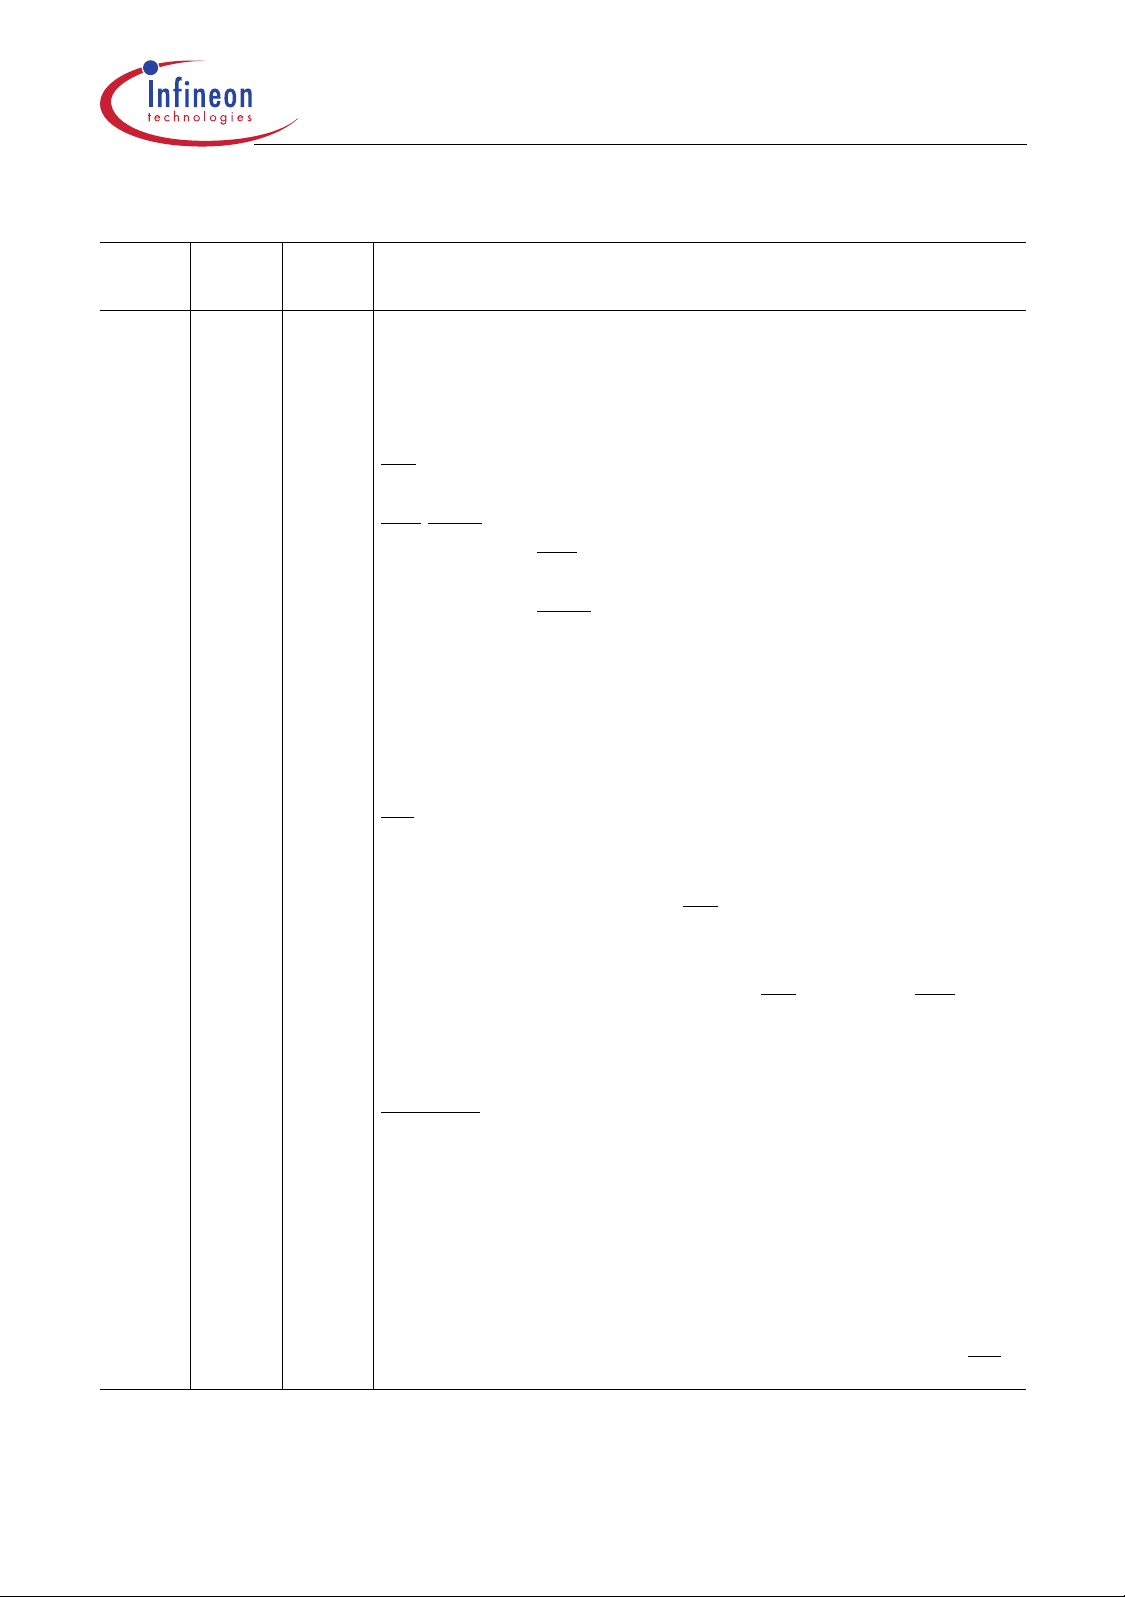
Table 2 Pin Definitions and Functions (cont’d)
Symbol Pin
Num.
P20
P20.0
P20.1
P20.4
P20.5
P20.12
63
64
65
66
2
Input
Outp.
IO
O
O
O
I
O
Function
Port 20 is a 6-bit bidirectional I/O port. Each pin can be
programmed for input (output driver in high-impedance
state) or output. The input threshold of Port 20 is selectable
(standard or special).
The following Port 20 pins also serve for alternate functions:
RD External Memory Read Strobe, activated for
every external instruction or data read access.
WR/WRL External Memory Write Strobe.
In WR-mode this pin is activated for every
external data write access.
In WRL-mode this pin is activated for low byte
data write accesses on a 16-bit bus, and for
every data write access on an 8-bit bus.
ALE Address Latch Enable Output.
Can be used for latching the address into
external memory or an address latch in the
multiplexed bus modes.
EA External Access Enable pin.
A low level at this pin during and after Reset
forces the XC164 to latch the configuration fr om
PORT0 and pin RD, and to begin instruction
execution out of external memory.
A high level forces the XC164 to latch the
configuration from pins RD, ALE, and WR, and
to begin instruction execution out of the internal
program memory. "ROMless" versions must
have this pin tied to ‘0’.
RSTOUT Internal Reset Indication Output.
Is activated asynchronously with an external
hardware reset. It may also be activated
(selectable) synchronously with an internal
software or watchdog reset.
Is deactivated upon the execution of the EINIT
instruction, optionally at the end of reset, or at
any time (before EINIT) via user software.
General Device Information
Note: Port 20 pins may input configuration values (see EA).
Data Sheet 10 V2.1, 2003-06
Page 15
XC164
Derivatives
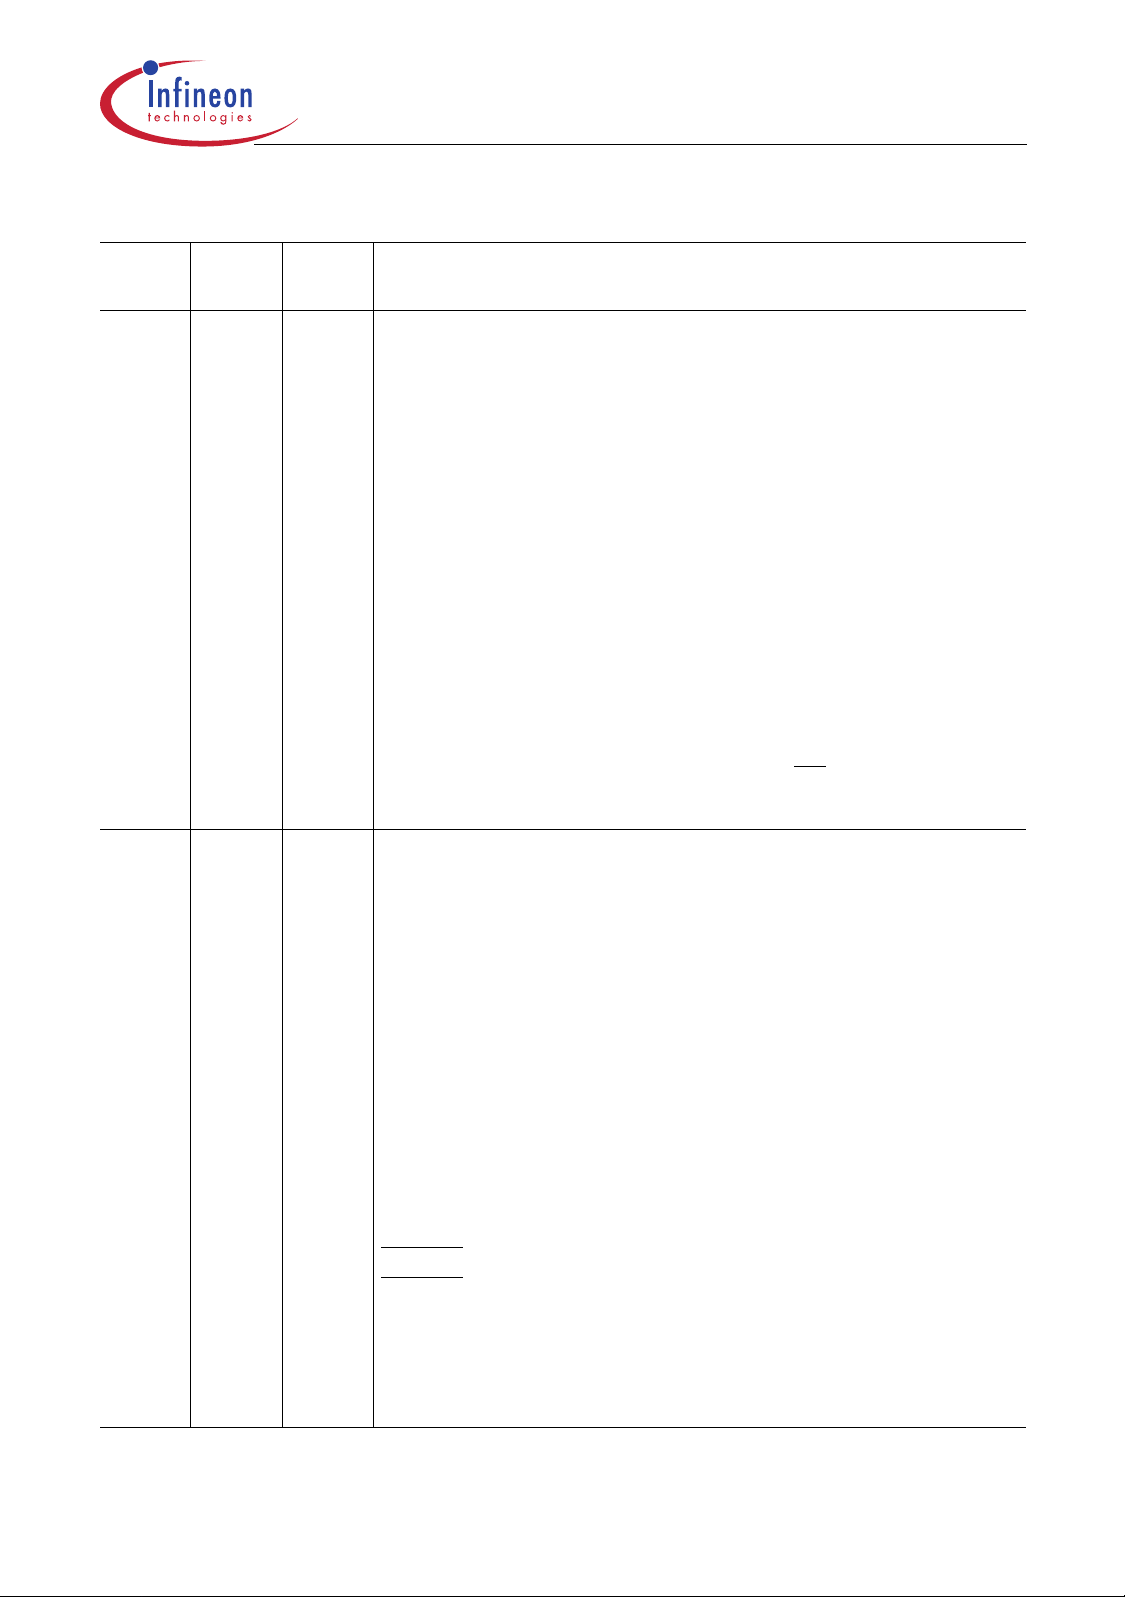
Table 2 Pin Definitions and Functions (cont’d)
Symbol Pin
Num.
PORT0
P0L.0-7
P0H.0-3
P0H.4-7
67 - 74
4 - 7
75 - 78
Input
Outp.
IO PORT0 consists of the two 8-bit bidirectional I/O ports P0L
Function
and P0H. Each pin can be programmed for input (output
driver in high-impedance state) or output.
In case of an external bus configuration, PORT0 serves as
the address (A) and address/data (AD) bus in multiplexed
bus modes and as the data (D) bus in demultiplexed bus
modes.
Demultiplexed bus modes:
Data Path Width: 8-bit 16-bit
P0L.0 – P0L.7: D0 – D7 D0 - D7
P0H.0 – P0H.7: I/O D8 - D15
Multiplexed bus modes:
Data Path Width: 8-bit 16-bit
P0L.0 – P0L.7: AD0 – AD7 AD0 - AD7
P0H.0 – P0H.7: A8 - A15 AD8 - AD15
General Device Information
PORT1
P1L.0
P1L.1
P1L.2
P1L.3
P1L.4
P1L.5
P1L.6
P1L.7
P1H
79
80
81
82
83
84
85
86
…
IO
I/O
O
I/O
O
I/O
O
O
I
I/O
Note: At the end of an external reset (EA = 0) PORT0 also
may input configuration values
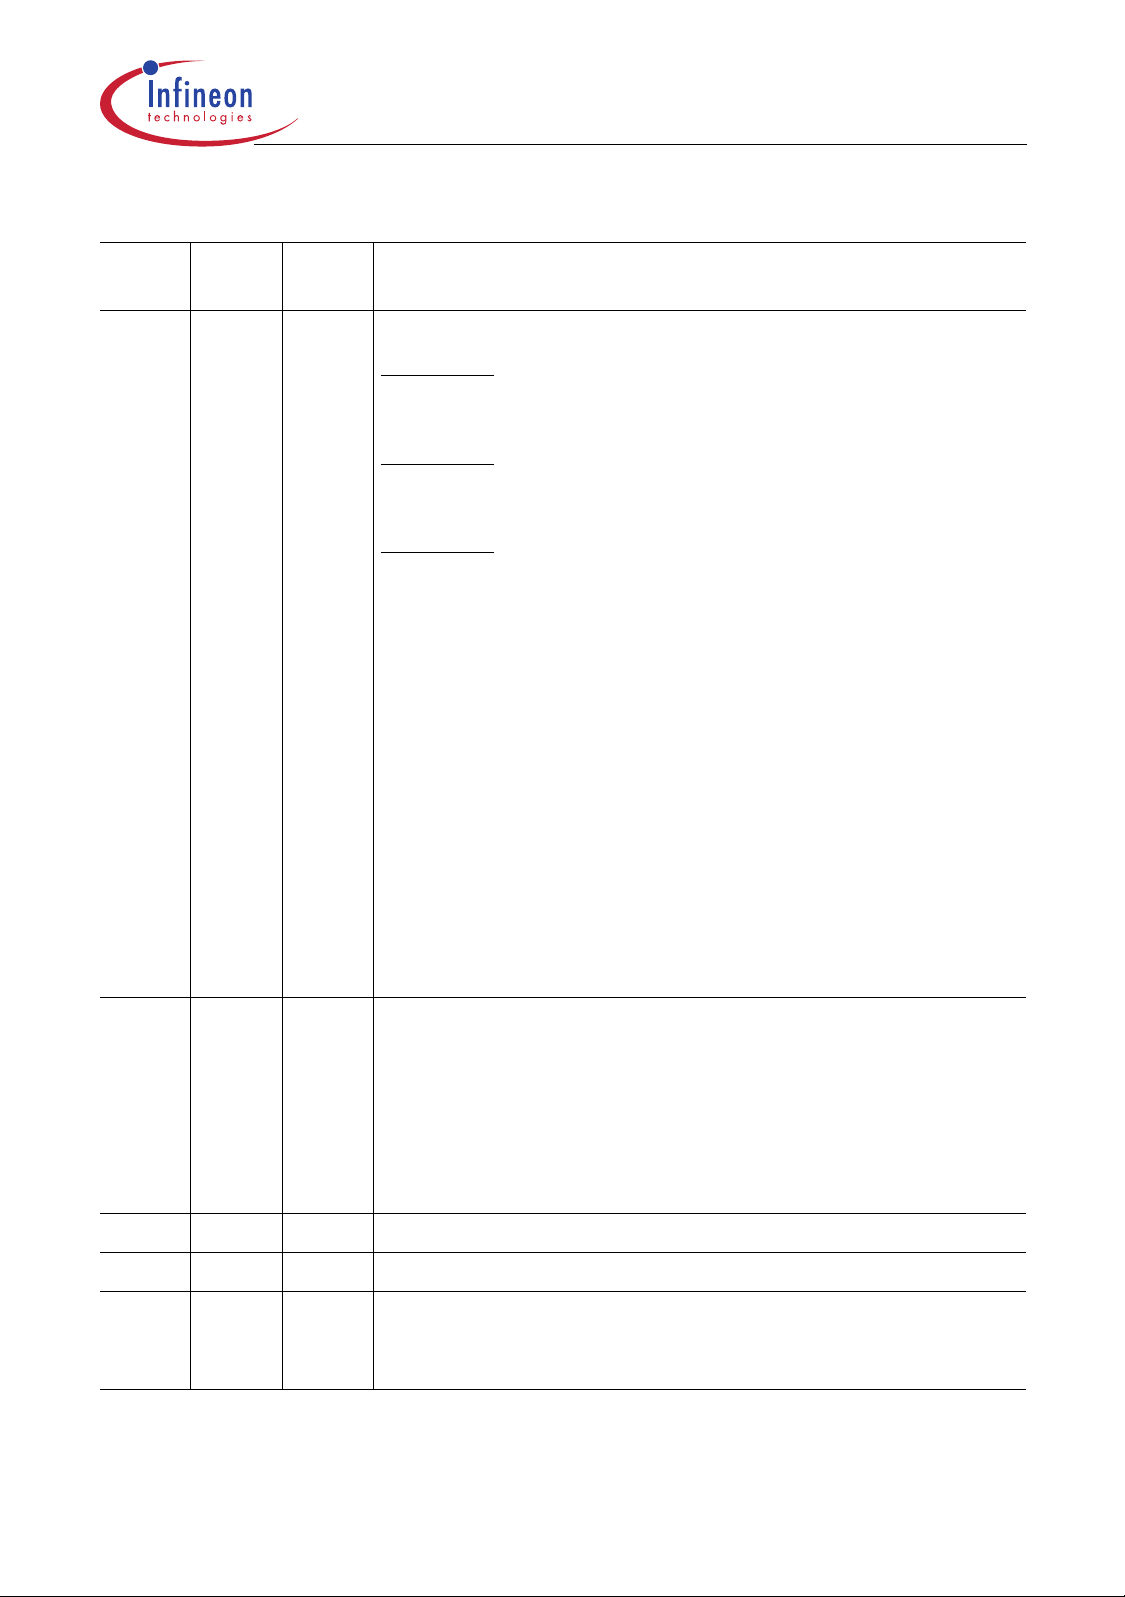
PORT1 consists of the two 8-bit bidirectional I/O ports P1L
and P1H. Each pin can be programmed for input (output
driver in high-impedance state) or output.
PORT1 is used as the 16-bit address bus (A) in
demultiplexed bus modes (also after switching from a
demultiplexed to a multiplexed bus mode).
The following PORT1 pins also serve for alt. functions:
CC60 CAPCOM6: Input / Output of Channel 0
COUT60 CAPCOM6: Output of Channel 0
CC61 CAPCOM6: Input / Output of Channel 1
COUT61 CAPCOM6: Output of Channel 1
CC62 CAPCOM6: Input / Output of Channel 2
COUT62 CAPCOM6: Output of Channel 2
COUT63 Output of 10-bit Compare Channel
CTRAP CAPCOM6: Trap Input
CTRAP is an input pin with an internal pullup resistor. A low
level on this pin switches the CAPCOM6 compare outputs to
the logic level defined by software (if enabled).
CC22IO CAPCOM2: CC22 Capture Inp./Compare Outp.
…continued…
Data Sheet 11 V2.1, 2003-06
Page 16
XC164
Derivatives
Table 2 Pin Definitions and Functions (cont’d)
Symbol Pin
Num.
PORT1
Input
Outp.
IO
Function
…continued…
(cont’d)
P1H.0
P1H.1
P1H.2
P1H.3
P1H.4
P1H.5
P1H.6
P1H.7
89
90
91
92
93
94
95
96
I
I
I/O
I
I
I/O
I
I
I/O
I
I/O
I
I
I/O
I
I/O
I
I/O
I
I/O
I
CC6POS0 CAPCOM6: Position 0 Input,
EX0IN Fast External Interrupt 0 Input (default pin),
CC23IO CAPCOM2: CC23 Capture Inp./Compare Outp.
CC6POS1 CAPCOM6: Position 1 Input,
EX1IN Fast External Interrupt 1 Input (default pin),
MRST1 SSC1 Master-Receive/Slave-Transmit In/Out.
CC6POS2 CAPCOM6: Position 2 Input,
EX2IN Fast External Interrupt 2 Input (default pin),
MTSR1 SSC1 Master-Transmit/Slave-Receive Out/Inp.
T7IN CAPCOM2: Timer T7 Count Input,
SCLK1 SSC1 Master Clock Output / Slave Clock Input,
EX3IN Fast External Interrupt 3 Input (default pin),
EX0IN Fast External Interrupt 0 Input (alternate pin A)
CC24IO CAPCOM2: CC24 Capture Inp./Compare Outp.,
EX4IN Fast External Interrupt 4 Input (default pin)
CC25IO CAPCOM2: CC25 Capture Inp./Compare Outp.,
EX5IN Fast External Interrupt 5 Input (default pin)
CC26IO CAPCOM2: CC26 Capture Inp./Compare Outp.,
EX6IN Fast External Interrupt 6 Input (default pin)
CC27IO CAPCOM2: CC27 Capture Inp./Compare Outp.,
EX7IN Fast External Interrupt 7 Input (default pin)
General Device Information
XTAL2
XTAL199100
O
I
XTAL2: Output of the oscillator amplifier circuit
XTAL1: Input to the oscillator amplifier and input to
the internal clock generator
To clock the device from an external source, drive XTAL1,
while leaving XTAL2 unconnected. Minimum and maximum
high/low and rise/fall times specified in the AC
Characteristics must be observed.
V
AREF
V
AGND
V
DDI
28 - Reference voltage for the A/D converter.
29 - Reference ground for the A/D converter.
35, 97 - Digital Core Supply Voltage (On-Chip Modules):
+2.5 V during normal operation and idle mode.
Please refer to the Operating Conditions
Data Sheet 12 V2.1, 2003-06
Page 17
XC164
Derivatives
General Device Information
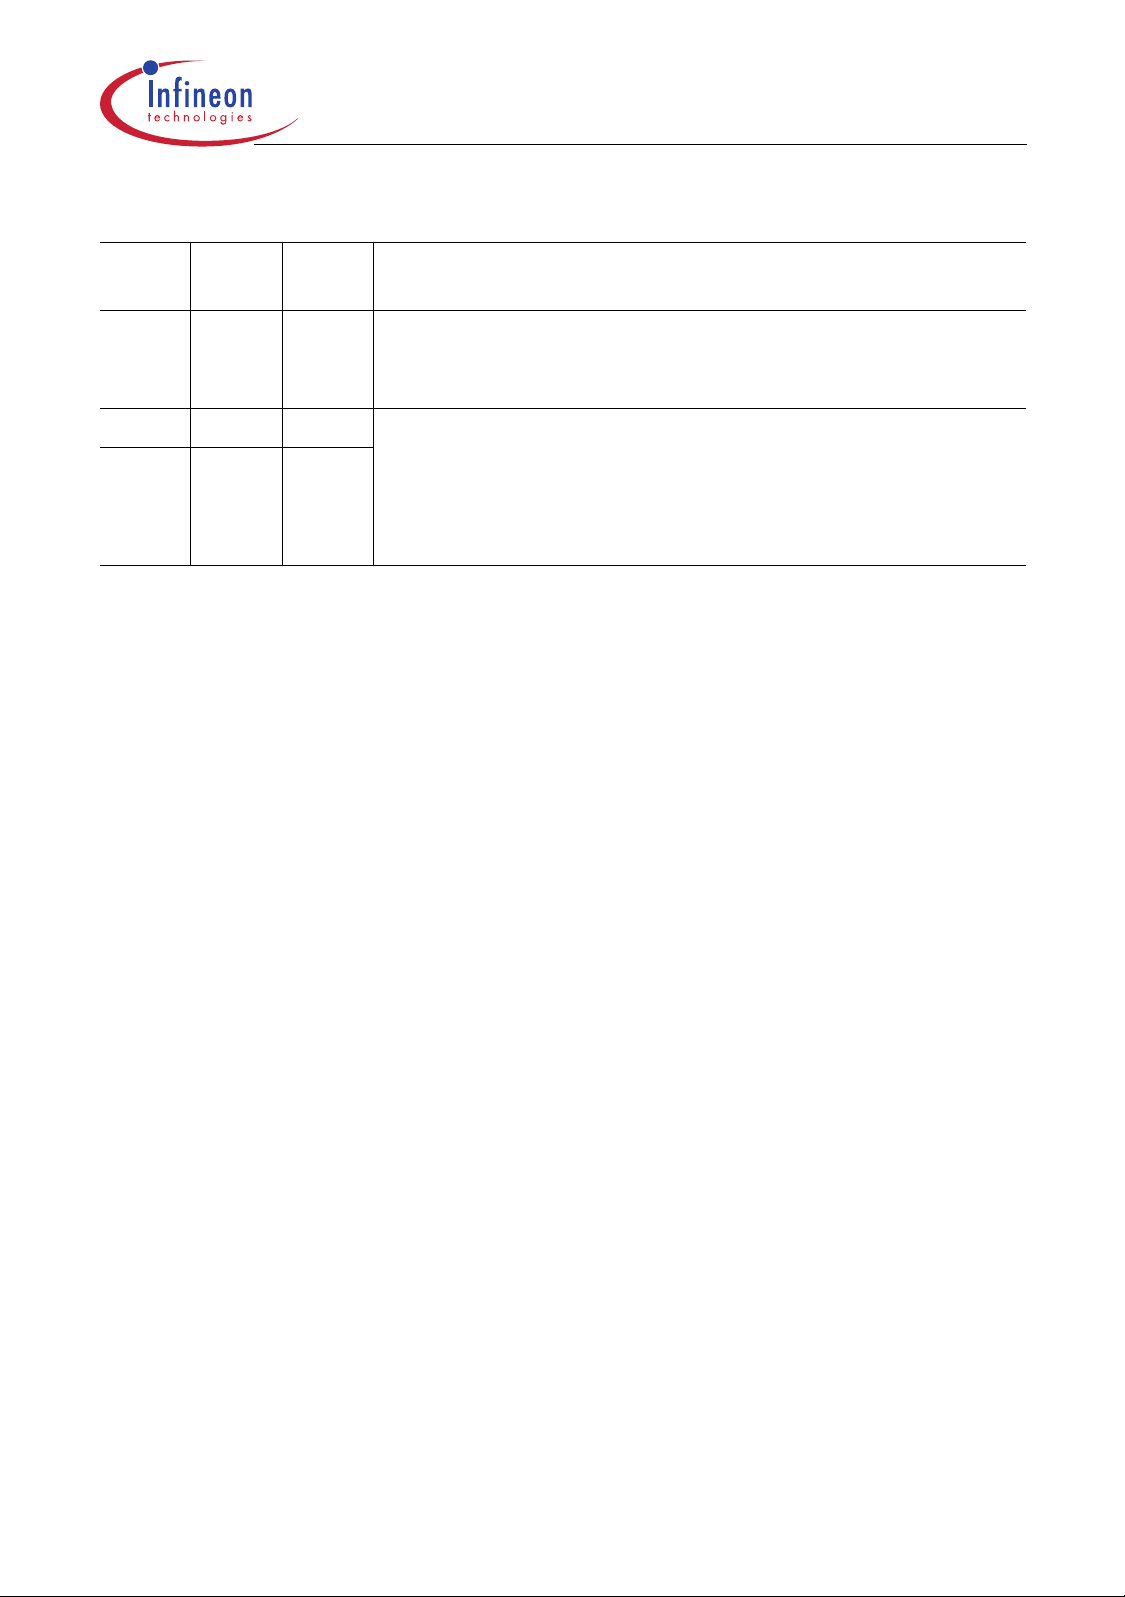
Table 2 Pin Definitions and Functions (cont’d)
Symbol Pin
Num.
V
DDP
9, 17,
38, 61,
87
V
V
SSI
SSP
34, 98 - Digital Ground.
8, 16,
37, 62,
88
Input
Function
Outp.
- Digital Pad Supply Voltage (Pin Output Drivers):
+5 V during normal operation and idle mode.
Please refer to the Operating Conditions
-
Connect decoupling capacitors to adjacent VDD/VSS pin
pairs as close as possible to the pins.
All VSS pins must be connected to the gro und-line o r groundplane.
1)
The CAN interface lines are assigned to ports P4 and P9 under software control.
Data Sheet 13 V2.1, 2003-06
Page 18
XC164
Derivatives
Functional Description
3 Functional Description
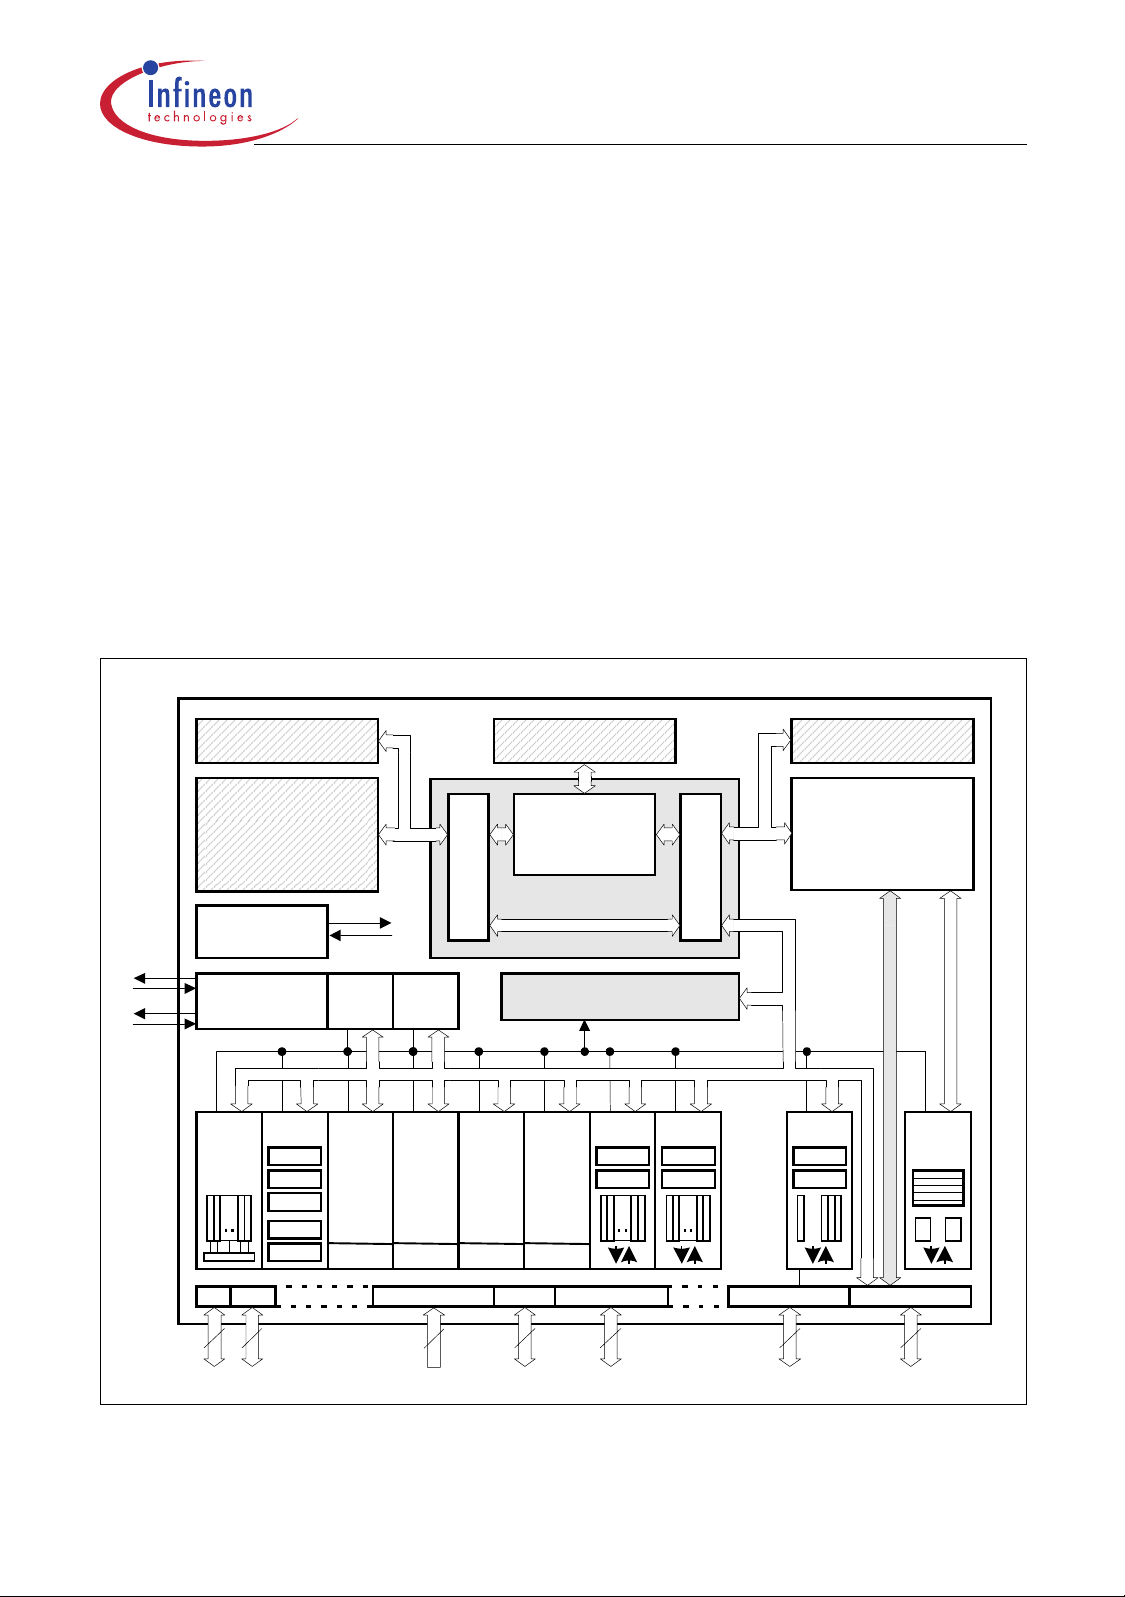
The architecture of the XC164 combines advantages of RISC, CISC, and DSP
processors with an advanced peripheral subsystem in a very well-balanced way. In
addition, the on-chip memory blocks allow the design of compact systems-on-silicon with
maximum performance (computing, control, communication).
The on-chip memory blocks (program code-memory and SRAM, dual-port RAM, data
SRAM) and the set of g eneric perip herals are connected to the CPU via separate bu ses.
Another bus, the LXBus, connects additional on-chip resoures as well as external
resources (see Figure 3).
This bus structure enhances the overall system performance by enabling the concurrent
operation of several subsystems of the XC164.
The following block diagram gives an overview of the different on-chip components and
of the advanced, high bandwidth internal bus structure of the XC164.
PSRAM DPRAM DSRAM
XTAL
ProgMem
Flash / RO M
128 KBytes
OCDS
Debug Support
Osc / PLL
Clock Generation
ADC
8/10-Bit
12/1 6
Channels
P 20
GPT
T2
T3
T4
T5
T6
65
RTC WDT
BRGen
ASC1
(USART)
BRGen
Port 5
ASC0
(USART)
14
PMU
SSC0
(S PI)
BRGen
CPU
C166SV2-Core
Interrupt & PEC
SSC1
(SPI)
BRGen
CC1
T0
T1
148
DMU
Interrupt Bu s
Peripheral Data Bus
CC2
T7
T8
CC6
T12
T13
PORT1 PORT0Port 3Port 4Port 9
16
EBC
XBUS Control
External Bus
Control
Twin
CAN
A B
16
MC B04323_x4.vsd
Figure 3 Block Diagram
Data Sheet 14 V2.1, 2003-06
Page 19
XC164
Derivatives
Functional Description
3.1 Memory Subsystem and Organization
The memory space of the XC164 is configured in a Von Neumann architecture, which
means that all internal and external resources, such as code memory, data memory,
registers and I/O ports, are organized within the same linear address space. This
common memory space includes 16 Mbytes and is arranged as 256 segments of
64 Kbytes each, where each segment consists of four data pages of 16K bytes each.
The entire memory space can be accessed bytewise or wordwise. Portions of the onchip DPRAM and the register spaces (E/SFR) have additionally been made directly
bitaddressable.
The internal data memory areas and the Special Function Register areas (SFR and
ESFR) are mapped into segment 0, the system segment.
The Program Mana gement Uni t ( PMU) handl es all code fetches and, therefore, contr ols
accesses to the program memories, such as Flash memory, ROM, and PSRAM.
The Data Management Unit (DMU) handles all data transfers and, therefore, controls
accesses to the DSRAM and the on-chip peripherals.
Both units (PMU and DMU) are connected via the high-speed system bus to exchange
data. This is requ ired if operands are re ad from p rogram memory, code or data i s written
to the PSRAM, code is fetched from external memory, or data is read from or written to
external resources, including pe ripherals on the LX bus ( such as TwinCAN). The system
bus allows concurrent two-way communication for maximum transfer performance.
128 Kbytes of on-chip Flash memory or mask-programmable ROM stor e code o r
constant data. The on-chip Flash memory is organized as four 8-Kbyte sectors, one
32-Kbyte sector, and one 64-Kbyte sector. Each sector can be separately write
protected1), erased and programmed (in blocks of 128 Bytes). The complete Flash or
ROM area can be read-protected. A password sequence temporarily unlocks protected
areas. The Flash module combines very fast 64-bit one-cycle read accesses with
protected and efficient writing algorithms for programming and erasing. Thus, program
execution out of the internal Flash results in maximum performance. Dynamic error
correction provides extremely high read data security for all read accesses.
Programming typically takes 2 ms per 128-byte block (5 ms max.), erasing a sector
typically takes 200 ms (500 ms max.).
2 Kbytes of on-chip Program S RAM (PSRAM ) are provided to store user code or data.
The PSRAM is accessed via the PMU and is therefore optimized for code fetches.
2 Kbytes of on-chip Data SRAM (DSRAM ) are provided as a storage for general user
data.The DSRAM is accessed via the DMU and is therefor e optimized for data accesses.
2 Kbytes of on-chip Dual-Port RAM (DPRAM) are provided as a storage for user
defined variables, for the system stack, general purpose register banks. A register bank
can consist of up to 16 wordw ide (R0 to R15) and/or bytew ide (RL0, RH0, …, RL7, RH7)
1)
Each two 8-Kbyte sectors are combined for write-protection purposes.
Data Sheet 15 V2.1, 2003-06
Page 20
XC164
Derivatives
Functional Description
so-called General Purpose Registers (GPRs).
The upper 256 bytes of the DPRAM are directly bitaddressable. When used by a GPR,
any location in the DPRAM is bitaddressable.
1024 bytes (2 × 512 bytes) of the address space are reserved for the Special Function
Register areas (SFR space and ESFR space). SFRs are wordwide registers which are
used for controlling and monitoring functions of the different on-chip units. Unused SFR
addresses are reserved for future m embers of the XC166 Family. Therefore, they shou ld
either not be accessed, or written with zeros, to ensure upward comp atibility.
In order to meet the needs of designs where more memory is required than is provided
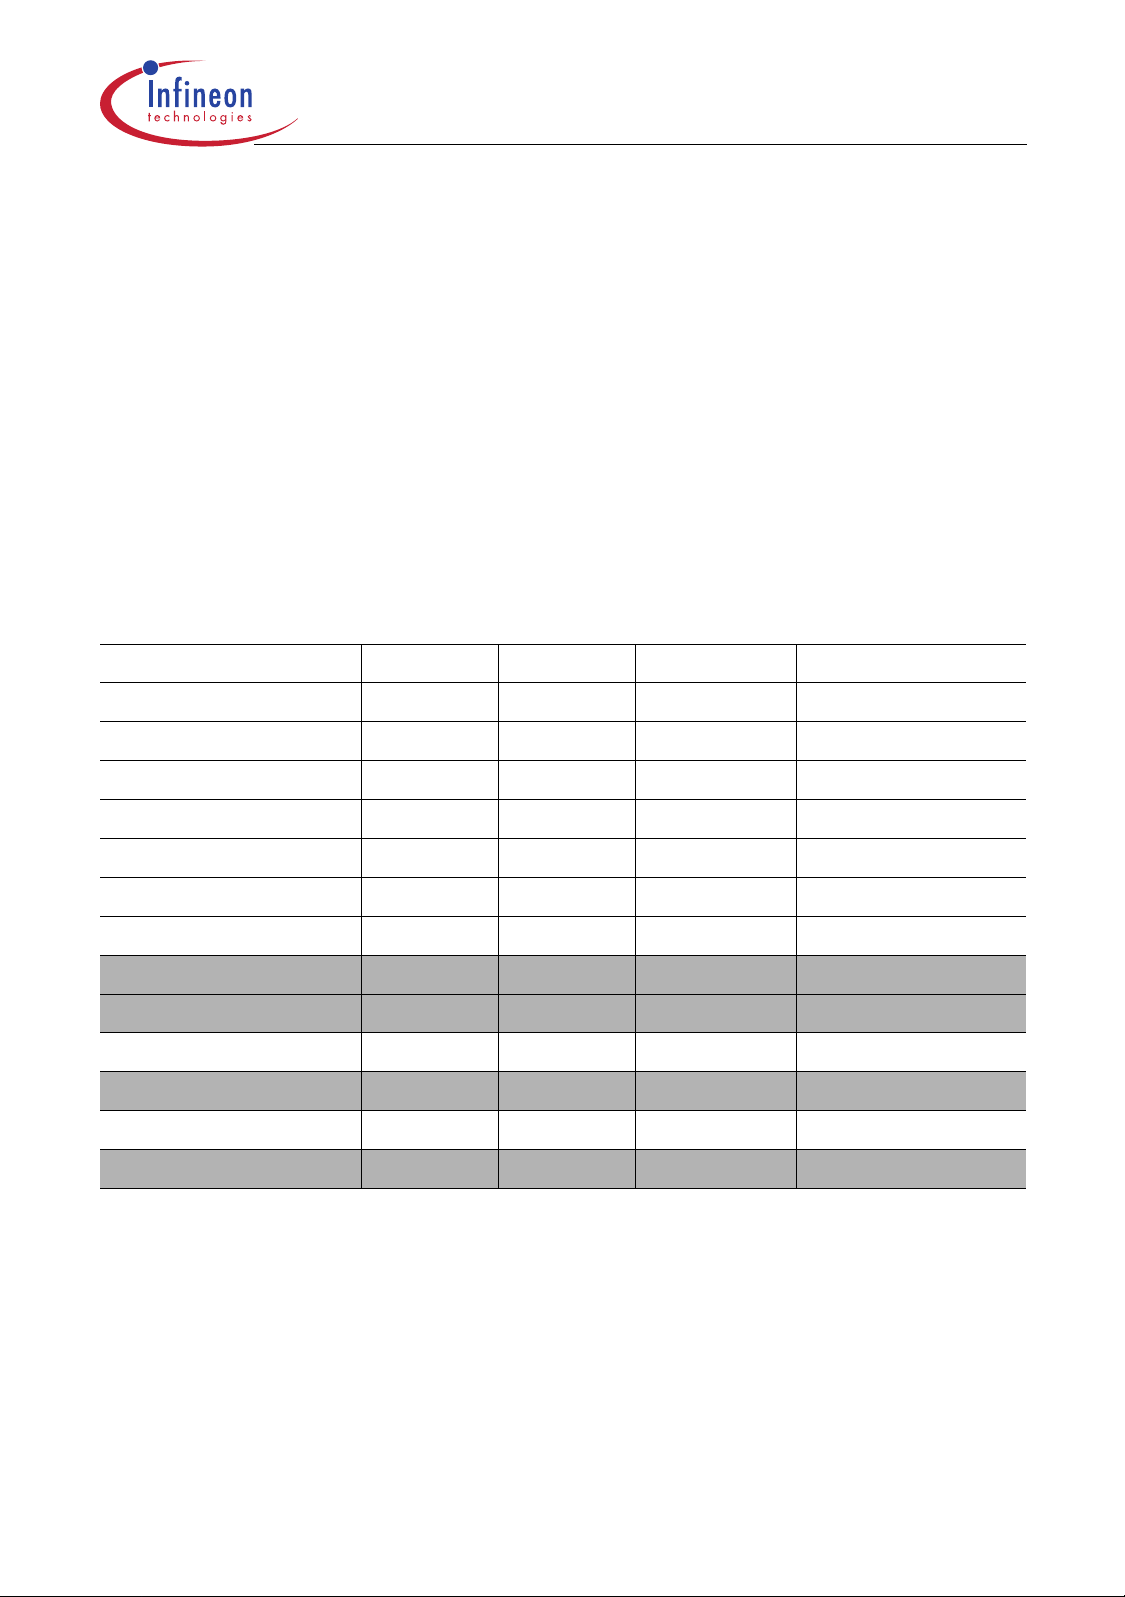
on chip, up to 12 Mbytes (approximately, see Table 3) of exter nal RAM and/or R OM can
be connected to the microcontroll er. Th e External Bus Interfa ce also pr ovides access to
external peripherals.
Table 3 XC164 Memory Map
Address Area Start Loc. End Loc. Area Size
Flash register space FF’F000
Reserved (Acc. trap)
Reserved for PSRAM
F8’0000
E0’0800
Program SRAM E0’0000
Reserved for pr. mem.
C2’0000
Program Flash/ROM C0’0000
Reserved
BF’0000
External memory area 40’0000
External IO area
4)
20’0800
TwinCAN registers 20’0000
External memory area 01’0000
Data RAMs and SFRs 00’8000
External memory area 00’0000
1)
Accesses to the shaded areas generate external bus accesses.
2)
The areas marked with “<“ are slightly smaller than indicated, see column “Notes”.
3)
Not defined register locations return a trap code.
4)
Several pipeline optimizations are not active within the external IO area. This is necessary to control external
peripherals properly.
1)
H
H
H
H
H
H
H
H
H
H
H
H
H
FF’FFFF
FF’EFFF
F7’FFFF
E0’07FF
DF’FFFF
C1’FFFF
BF’FFFF
BE’FFFF
3F’FFFF
20’07FF
1F’FFFF
00’FFFF
00’7FFF
2)
Notes
H
H
H
H
H
H
H
H
H
H
H
H
H
4 Kbytes Flash only
<0.5 Mbytes Minus Flash regs
<1.5 Mbytes Minus PSRAM
2 Kbytes Maximum
< 2 Mbytes Minus Flash/ROM
128 Kbytes
64 Kbytes
<8 Mbytes Minus res. seg.
<2 Mbytes Minus TwinCAN
2 Kbytes
<2 Mbytes Minus segment 0
32 Kbytes Partly used
32 Kbytes
3)
Data Sheet 16 V2.1, 2003-06
Page 21
XC164
Derivatives
Functional Description
3.2 External Bus Controller
All of the external memory accesses ar e perform ed by a particular on-chi p Ex ternal Bu s
Controller (EBC). It can be programmed either to Single Chip Mode when no external
memory is required, or to one of four different external memory access modes1), which
are as follows:
– 16 … 24-bit Addresses, 16-bit Data, Demultiplexed
– 16 … 24-bit Addresses, 16-bit Data, Multiplexed
– 16 … 24-bit Addresses, 8-bit Data, Multiplexed
– 16 … 24-bit Addresses, 8-bit Data, Demultiplexed
In the demultiplexed bus modes, addresses are output on PORT1 and data is input/
output on PORT0 or P0L, respectively. In the multiplexed bus modes both addresses
and data use PORT0 for input/output. The high order address (segment) lines use
Port 4. The number of active segment address lines is selectable, re stricting the extern al
address space to 8 Mbytes … 64 Kbytes. This is required when interface lines are
assigned to Port 4.
Up to 4 external CS signals (3 windows plus default) can be generated in order to save
external glue logic. E xternal modules can di rectly be connecte d to the common address/
data bus and their individual select lines.
Important timing characteristics of the external bus interface have been made
programmable (via registers TCONCSx/FCONCSx) to allow the user the adaption of a
wide range of different types of memories and external peripherals.
In addition, up to 4 independent address windows may be defined (via registers
ADDRSELx) which control the access to different resources with different bus
characteristics. These address windows are arranged hierarchically where window 4
overrides window 3, and window 2 overrides window 1. All accesses to locations not
covered by these 4 address windows are controlled by TCONCS0/FCONCS0. The
currently active window can generate a chip select signal.
The external bus timing is related to the rising edge of the reference clock output
CLKOUT. The external bus protocol is compatible w ith that of the standard C166 Family.
The EBC also controls accesses to resources connected to the on-chip LXBus. The
LXBus is an internal representation of the external bus and allows accessing integrated
peripherals and modules in the same way as external components.
The TwinCAN module is connected and accessed via the LXBus.
1)
Bus modes are switched dynamically if several address windows with different mode settings are used.
Data Sheet 17 V2.1, 2003-06
Page 22
XC164
Derivatives
Functional Description
3.3 Central Processing Unit (CPU)
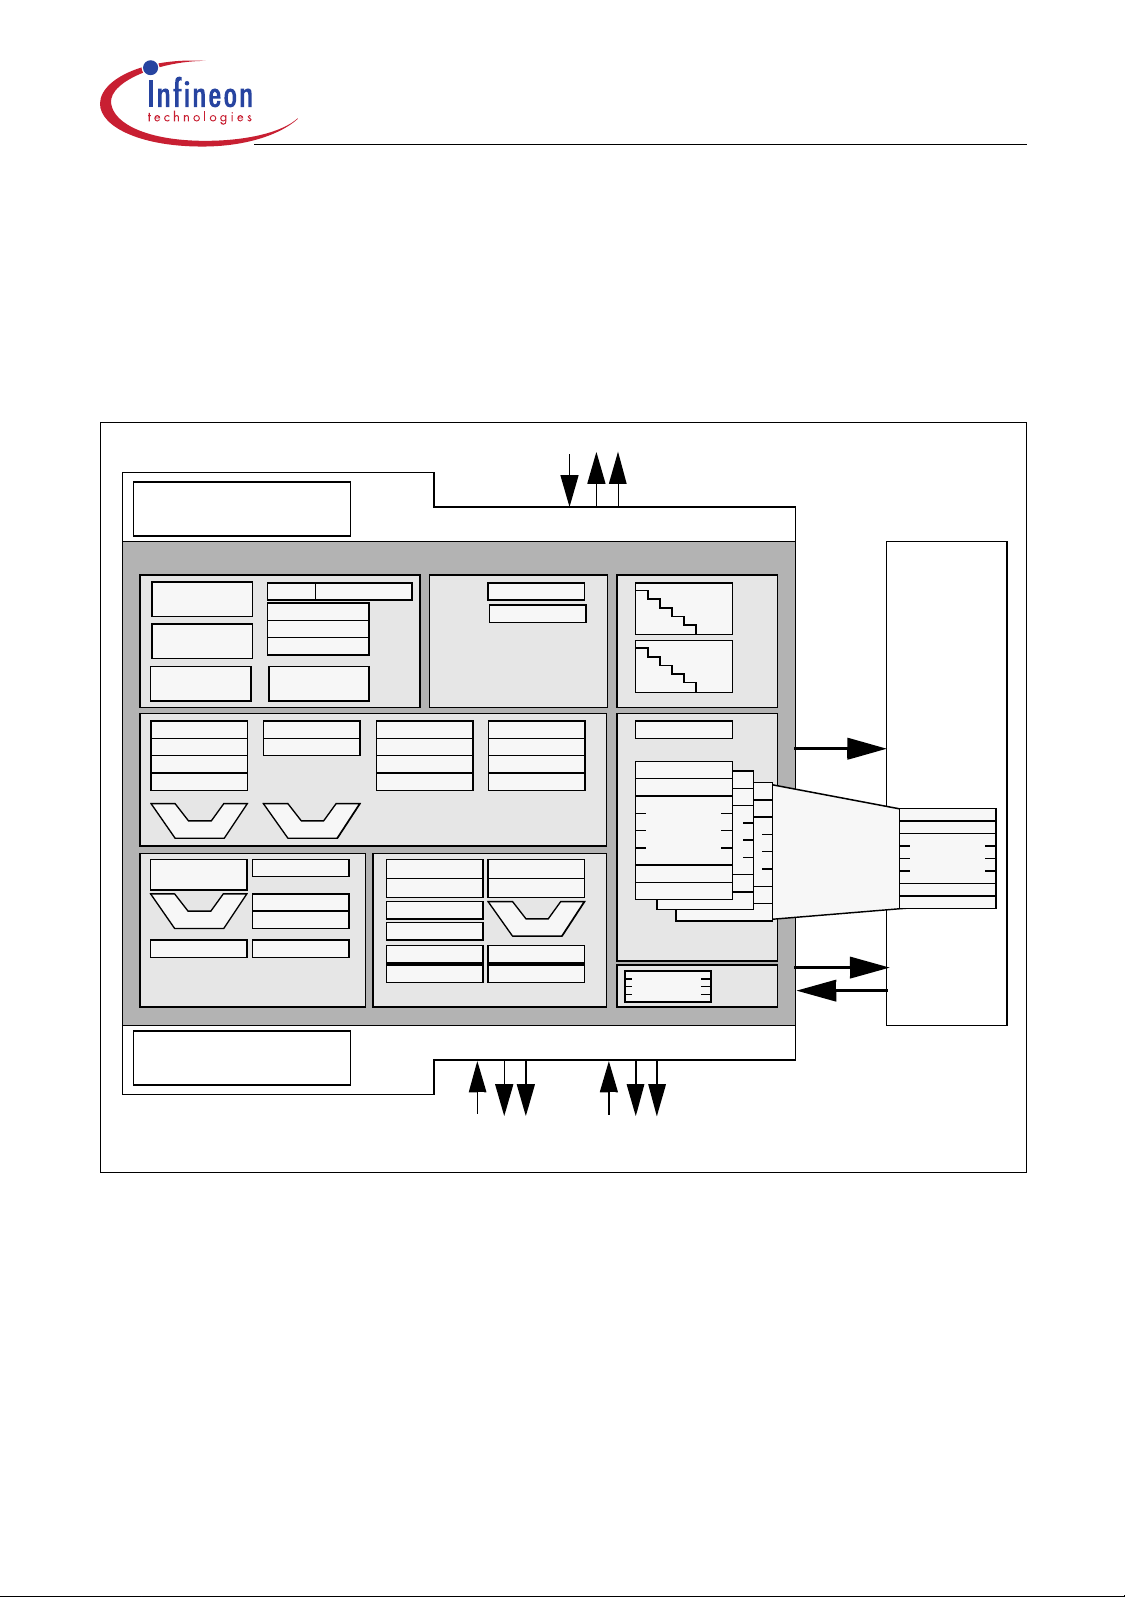
The main core of the CPU consists of a 5-stage execution pipeline with a 2-stage
instruction-fetch pipeline, a 1 6-bit arithme tic an d logic u nit (ALU), a 32-bi t/40-bi t multi ply
and accumulate unit (MA C), a register- fi le providi ng th ree r egister banks, and dedicated
SFRs. The ALU features a multiply and divide unit, a bit-mask generator, and a barrel
shifter.
System-Bus
Internal Program M em o ry
CPU
Prefetch Unit
Branch Unit
FIFO
IDX0
IDX1
QX0
QX1
Multiply Unit
+/-
MAH
CSP
CPUCON 1
CPUCON2
CPUID
Return Stack
QR0
QR1
+/-+/-
MRW
MCW
MSW
MAL
MAC
PMU
IP
IFU
Injection/Exception
DPP0
DPP1
DPP2
DPP3
Division Unit
Multiply Unit
MDC
PSW
Zeros
data in
VECSEG
TFR
Handler
SPSEG
SP
STKOV
STKUN
ADU
Bit-Mask-Gen.
Barrel-Shifter
+/-
MDLMDH
Ones
ALU
address
data out
data in
address
da ta ou t
DPRAM
2-Stage
Prefetch
Pipeline
5-Stage
Pipeline
IPIP
CP
R15
R14
GPRs
R1
R0
R15
R14
GPRs
GPRs
R1
R0
R15
R14
R1
R0
address
R15
R14
GPRs
R1
R0
RF
data in
Buffer
address
data out
data in
WB
data out
SRAM
DMU
Peripheral-Bus
System-Bus
Figure 4 CPU Block Diagram
Based on these hardware provisions, mo st of the XC164’s instructions can be executed
in just one machine cycle which requir es 25 ns at 40 MHz CPU clock. For example, shift
and rotate instructions are always processed during one machine cycle independent of
the number of bits to be shifted. Also multiplication and most MAC instructions execute
in one single cycle. All multi ple -cycl e instructions have been optimized so that they can
be executed very fast as well: for e xample, a 32-/16-bit division is started within 4 cycles,
while the remaining 15 cycles are executed in the background. Another pipeline
Data Sheet 18 V2.1, 2003-06
Page 23
XC164
Derivatives
optimization, the branch target prediction, allows eliminating the execution time of
branch instructions if the prediction was correct.
The CPU has a register context consisting of up to thr ee register banks with 16 wordwide
GPRs each at its disposal. One of these register banks is physically allocated within the
on-chip DPRAM area. A Context Pointer (CP) register determines the base address of
the active register bank to be accessed by the CPU at any time. The number of register
banks is only restricted by the available internal RAM space. For easy parameter
passing, a register bank may overlap others.
A system stack of up to 32 Kwords is provided as a storage for temporary data. The
system stack can be allocated to an y location within th e address space ( preferably in the
on-chip RAM area), and it is accessed by the CPU via the stack pointer (SP) register.
Two separate SFRs, STKOV and STKUN, are implicitly compared against the stack
pointer value upon each stack access for the detecti on of a stack overflow or under fl ow.
The high performance o ffered by the hardware implementation of the C PU can efficiently
be utilized by a programmer via the highly efficient XC164 instruction set which includes
the following instruction classes:
– Standard Arithmetic Instructions
– DSP-Oriented Arithmetic Instructions
– Logical Instructions
– Boolean Bit Manipulation Instructions
– Compare and Loop Control Instructions
– Shift and Rotate Instructions
– Prioritize Instruction
– Data Movement Instructions
– System Stack Instructions
– Jump and Call Instructions
– Return Instructions
– System Control Instructions
– Miscellaneous Instructions
Functional Description
The basic instruction l ength is ei ther 2 or 4 bytes. Possibl e oper and t ypes are bits, b ytes
and words. A variety of direct, indirect or immediate addressing modes are provided to
specify the required operands.
Data Sheet 19 V2.1, 2003-06
Page 24
XC164
Derivatives
Functional Description
3.4 Interrupt System
With an interrupt response time of typically 8 CPU clocks (in case of internal program
execution), the XC164 is capable of reacting very fast to the occurrence of nondeterministic events.
The architecture of the XC164 supports several mechanisms for fast and flexible
response to service requests that can be generated from various sources internal or
external to the microcontroller. Any of these interrupt requests can be programmed to
being serviced by the Interrupt Controller or by the Peripheral Event Controller (PEC).
In contrast to a standard interrupt service where the current program execution is
suspended and a branch to the interrupt vector table is performed, just one cycle is
‘stolen’ from t he curr ent CPU a ctivity to perfor m a PEC service. A PEC service i mplies a
single byte or word data transfer between any two memory locations with an additional
increment of either th e PEC source, or the destin ation pointer, or both. An individual PEC
transfer counter is implicitly decremented for each PEC service except when performing
in the continuous transfer mode. When this counter reaches zero, a standard interr upt is
performed to the corresponding source related vector location. PEC services are very
well suited, for example, for supporting the transmission or reception of blocks of data.
The XC164 has 8 PEC channels each of which offers such fast interrupt-driven data
transfer capabilities.
A separate control register which contains an interrupt request flag, an interrupt enable
flag and an interrupt priori ty bitfield exists for each of the possible interrupt node s. Via its
related register, each node can be programmed to one of sixteen interrupt priority levels.
Once having been accepted by the CPU, an interrupt service can only be interrupted by
a higher prioritized service request. For the standard interrupt processing, each of the
possible interrupt nodes has a dedicated vector location.
Fast external interrupt inputs are provided to service external interrupts with high
precision requirements. These fast interrupt inputs feature programmable edge
detection (rising edge, falling edge, or both edges).
Software interrup ts are supported by means of the ‘TRAP’ instruction in combinati on with
an individual trap (interrupt) number.
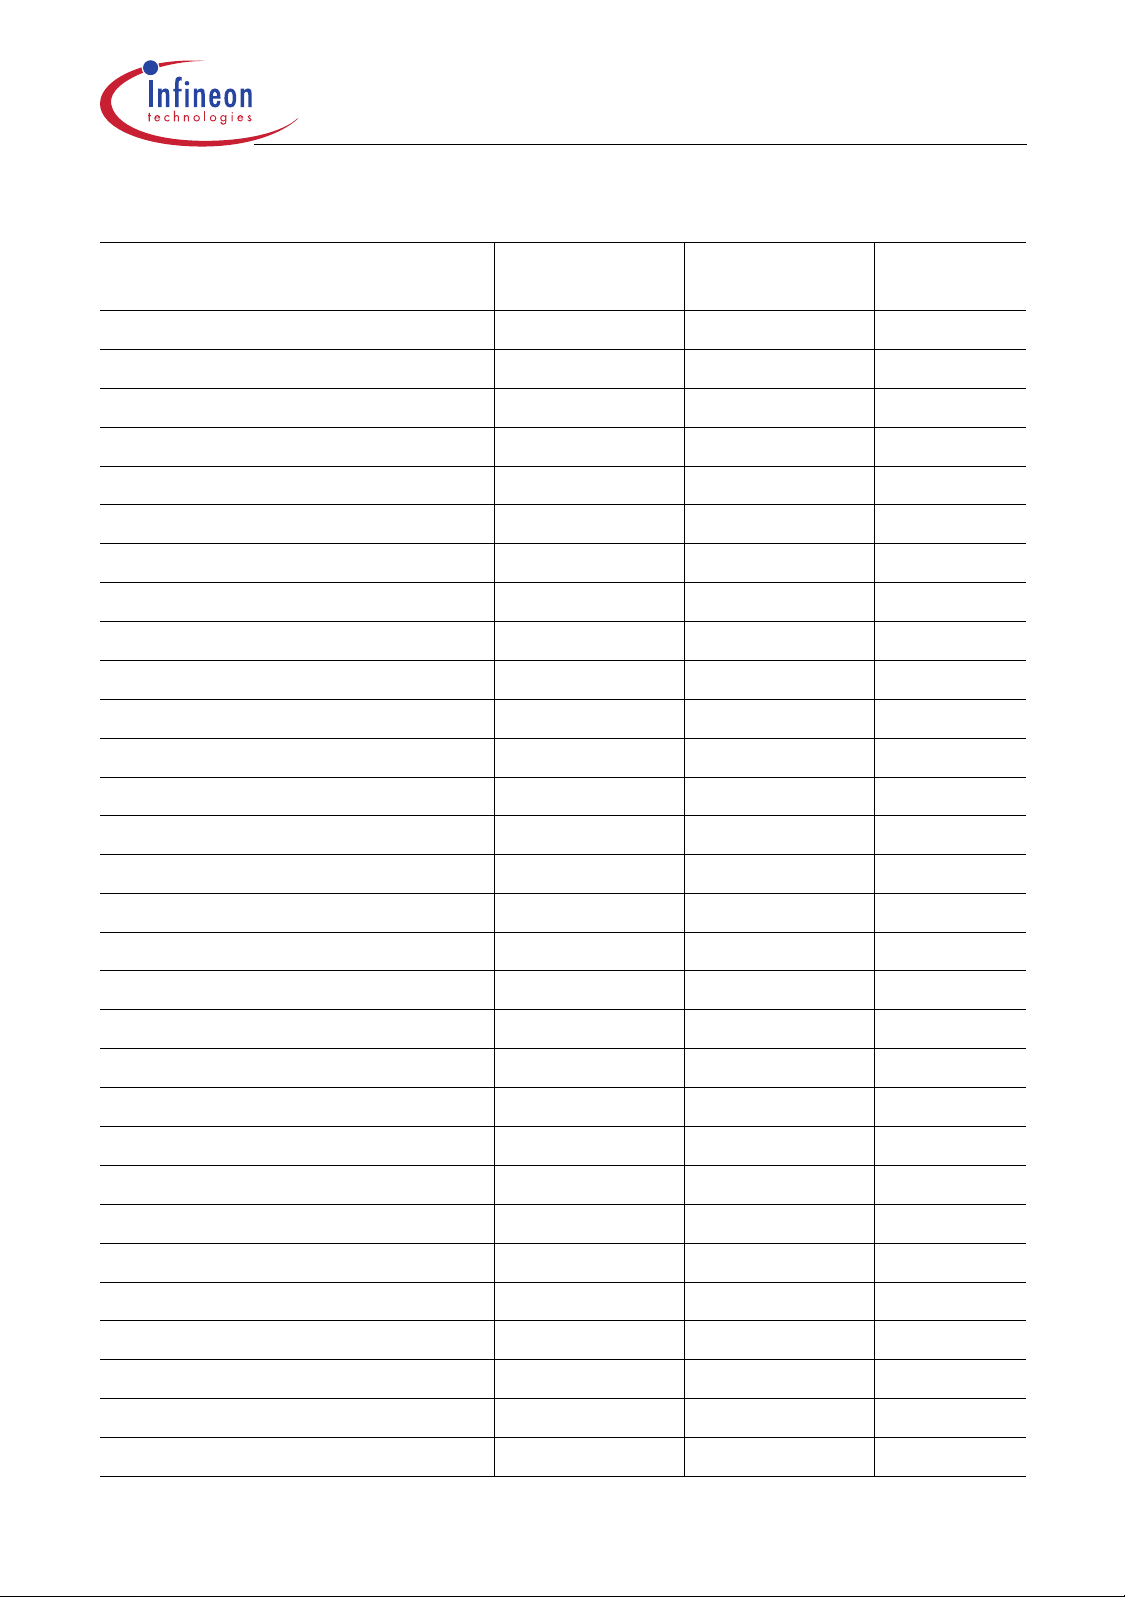
Table 4 shows all of the possible XC164 interrupt sources and the corresponding
hardware-related interrupt flags, vectors, vector locations and trap (interrupt) numbers.
Note: Interrupt nodes which are not assigned to peripherals (unassigned nodes), may
be used to generate software controlled interrupt requests by setting the
respective interrupt request bit (xIR).
Data Sheet 20 V2.1, 2003-06
Page 25
XC164
Derivatives
Functional Description
Table 4 XC164 I nterrupt Nodes
Source of Interrupt or PEC
Service Request
Control
Register
Vector
Location
CAPCOM Register 0 CC1_CC0IC xx’0040
CAPCOM Register 1 CC1_CC1IC xx’0044
CAPCOM Register 2 CC1_CC2IC xx’0048
CAPCOM Register 3 CC1_CC3IC xx’004C
CAPCOM Register 4 CC1_CC4IC xx’0050
CAPCOM Register 5 CC1_CC5IC xx’0054
CAPCOM Register 6 CC1_CC6IC xx’0058
CAPCOM Register 7 CC1_CC7IC xx’005C
CAPCOM Register 8 CC1_CC8IC xx’0060
CAPCOM Register 9 CC1_CC9IC xx’0064
CAPCOM Register 10 CC1_CC10IC xx’0068
CAPCOM Register 11 CC1_CC11IC xx’006C
CAPCOM Register 12 CC1_CC12IC xx’0070
CAPCOM Register 13 CC1_CC13IC xx’0074
CAPCOM Register 14 CC1_CC14IC xx’0078
CAPCOM Register 15 CC1_CC15IC xx’007C
CAPCOM Register 16 CC2_CC16IC xx’00C0
CAPCOM Register 17 CC2_CC17IC xx’00C4
CAPCOM Register 18 CC2_CC18IC xx’00C8
CAPCOM Register 19 CC2_CC19IC xx’00CC
CAPCOM Register 20 CC2_CC20IC xx’00D0
CAPCOM Register 21 CC2_CC21IC xx’00D4
CAPCOM Register 22 CC2_CC22IC xx’00D8
CAPCOM Register 23 CC2_CC23IC xx’00DC
CAPCOM Register 24 CC2_CC24IC xx’00E0
CAPCOM Register 25 CC2_CC25IC xx’00E4
CAPCOM Register 26 CC2_CC26IC xx’00E8
CAPCOM Register 27 CC2_CC27IC xx’00EC
CAPCOM Register 28 CC2_CC28IC xx’00E0
CAPCOM Register 29 CC2_CC29IC xx’0110
1)
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
Number
10H / 16
11H / 17
12H / 18
13H / 19
14H / 20
15H / 21
16H / 22
17H / 23
18H / 24
19H / 25
1AH / 26
1BH / 27
1CH / 28
1DH / 29
1EH / 30
1FH / 31
30H / 48
31H / 49
32H / 50
33H / 51
34H / 52
35H / 53
36H / 54
37H / 55
38H / 56
39H / 57
3AH / 58
3BH / 59
3CH / 60
44H / 68
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
Trap
Data Sheet 21 V2.1, 2003-06
Page 26
XC164
Derivatives
Functional Description
Table 4 XC164 Interrupt Nodes (cont’d)
Source of Interrupt or PEC
Service Request
Control
Register
Vector
Location
CAPCOM Register 30 CC2_CC30IC xx’0114
CAPCOM Register 31 CC2_CC31IC xx’0118
CAPCOM Timer 0 CC1_T0IC xx’0080
CAPCOM Timer 1 CC1_T1IC xx’0084
CAPCOM Timer 7 CC2_T7IC xx’00F4
CAPCOM Timer 8 CC2_T8IC xx’00F8
GPT1 Timer 2 GPT12E_T2IC xx’0088
GPT1 Timer 3 GPT12E_T3IC xx’008C
GPT1 Timer 4 GPT12E_T4IC xx’0090
GPT2 Timer 5 GPT12E_T5IC xx’0094
GPT2 Timer 6 GPT12E_T6IC xx’0098
GPT2 CAPREL Reg. GPT12E_CRIC xx’009C
A/D Conversion Comp l. ADC_CIC xx’00A0
A/D Overrun Error ADC_EIC xx’00A4
ASC0 Transmit ASC0_TIC xx’00A8
ASC0 Transmit Buffer ASC0_TBIC xx’011C
ASC0 Receive ASC0_RIC xx’00AC
ASC0 Error ASC0_EIC xx’00B0
ASC0 Autobaud ASC0_ABIC xx’017C
SSC0 Transmit SSC0_TIC xx’00B4
SSC0 Receive SSC0_RIC xx’00B8
SSC0 Error SSC0_EIC xx’00BC
PLL/OWD PLLIC xx’010C
ASC1 Transmit
2)
ASC1_TIC xx’0120
ASC1 Transmit Buffer ASC1_TBIC xx’0178
ASC1 Receive ASC1_RIC xx’0124
ASC1 Error ASC1_EIC xx’0128
ASC1 Autobaud ASC1_ABIC xx’0108
End of PEC Subch. EOPIC xx’0130
CAPCOM6 Timer T12 CCU6_T12IC xx’0134
1)
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
H
Number
45H / 69
46H / 70
20H / 32
21H / 33
3DH / 61
3EH / 62
22H / 34
23H / 35
24H / 36
25H / 37
26H / 38
27H / 39
28H / 40
29H / 41
2AH / 42
47H / 71
2BH / 43
2CH / 44
5FH / 95
2DH / 45
2EH / 46
2FH / 47
43H / 67
48H / 72
5EH / 94
49H / 73
4AH / 74
42H / 66
4CH / 76
4DH / 77
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
Trap
Data Sheet 22 V2.1, 2003-06
Page 27
XC164
Derivatives
Functional Description
Table 4 XC164 Interrupt Nodes (cont’d)
Source of Interrupt or PEC
Service Request
CAPCOM6 Timer T13 CCU6_T13IC xx’0138
CAPCOM6 Emergency CCU6_EIC xx’013C
CAPCOM6 CCU6_IC xx’0140
SSC1 Transmit SSC1_TIC xx’0144
SSC1 Receive SSC1_RIC xx’0148
SSC1 Error SSC1_EIC xx’014C
CAN0 CAN_0IC xx’0150
CAN1 CAN_1IC xx’0154
CAN2 CAN_2IC xx’0158
CAN3 CAN_3IC xx’015C
CAN4 CAN_4IC xx’0164
CAN5 CAN_5IC xx’0168
CAN6 CAN_6IC xx’016C
CAN7 CAN_7IC xx’0170
RTC RTC_IC xx’0174
Unassigned node --- xx’0100
Unassigned node --- xx’0104
Unassigned node --- xx’012C
Unassigned node --- xx’00FC
Unassigned node --- xx’0160
1)
Register VECSEG defines the segment where the vector table is located to.
Bitfield VECSC in register CPUCON1 defines the distance between two adjacent vectors. This table
represents the default setting, with a distance of 4 (two words) between two vectors.
2)
The interrupt nodes assigned to ASC1 are only available in derivatives including the ASC1. Otherwise, they
are unassigned nodes.
Control
Register
Vector
Location
H
H
H
H
H
H
H
H
H
H
H
H
H
H
1)
Number
4EH / 78
Trap
H
4FH / 79
50H / 80
51H / 81
52H / 82
H
53H / 83
54H / 84
55H / 85
56H / 86
H
57H / 87
59H / 89
5AH / 90
H
5BH / 91
5CH / 92
5DH / 93
40H / 64
41H / 65
H
H
4BH / 75
3FH / 63
58H / 88
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
D
Data Sheet 23 V2.1, 2003-06
Page 28
XC164
Derivatives
Functional Description
The XC164 also provides an excellent mechanism to identi fy and to pr ocess exceptions
or error conditions that arise during run-time, so-called ‘Hardware Traps’. Hardware
traps cause immediate non-maskable system reaction which is similar to a standard
interrupt service (branching to a dedicated vector table location). The occurence of a
hardware trap is additionally signified by an individual bit in the trap flag register (TFR).
Except when another higher prioritized trap service is in progress, a hardware trap will
interrupt any actual pro gram executi on . In turn , hardware trap ser vices can normall y not
be interrupted by standard or PEC interrupts.
Table 5 shows all of the possible exceptions or error conditions that can arise during run-
time:
Table 5 Hardware Trap Summary
Exception Condition Trap
Flag
Reset Functions:
–
– Hardware Reset
– Software Reset
– W-dog Timer Overflow
Trap
Vector
RESET
RESET
RESET
Vector
Location
xx’0000
xx’0000
xx’0000
H
H
H
1)
Trap
Number
00
H
00
H
00
H
Trap
Priority
III
III
III
Class A Hardware Traps:
– Non-Maskable Interrupt
– Stack Overflow
– Stack Underflow
– Software Break
NMI
STKOF
STKUF
SOFTBRK
NMITRAP
STOTRAP
STUTRAP
SBRKTRAP
xx’0008
xx’0010
xx’0018
xx’0020
02
H
H
H
H
04
06
08
H
H
H
H
II
II
II
II
Class B Hardware Traps:
– Undefined Opcode
– PMI Access Error
– Protected Instruction
UNDOPC
PACER
PRTFLT
BTRAP
BTRAP
BTRAP
xx’0028
xx’0028
xx’0028
0A
H
H
H
0A
0A
H
H
H
I
I
I
Fault
– Illegal Word Operand
ILLOPA
BTRAP
xx’0028
0A
H
H
I
Access
Reserved – – [2CH –
3CH]
Software Traps
– TRAP Instruction
–– Any
[xx’0000H –
xx’01FCH]
[0BH –
0FH]
Any
[00H –
7FH]
–
Current
CPU
Priority
in steps
of 4
H
1)
Register VECSEG defines the segment where the vector table is located to.
Data Sheet 24 V2.1, 2003-06
Page 29
XC164
Derivatives
Functional Description
3.5 On-Chip Debug Support (OCDS)
The On-Chip Debug Support system provides a broad range of debug and emulation
features built into the XC164. The user software running on the XC164 can thus be
debugged within the target system environment.
The OCDS is controlled by an external debugging device via the debug interface,
consisting of the IEEE-1149-conf orming JTAG port a nd a break inter face. The debugger
controls the OCDS via a set of dedicated registers accessible via the JTAG interface.
Additionally, the OCDS system can be controlled by the CPU, e.g. by a monitor program.
An injection interface allows the execution of OCDS-gener ated i nstructions by the CP U.
Multiple breakpoints can be triggered by on-chip hardware, by software, or by an
external trigger input. Single stepping is supported as well as the injection of arbitrary
instructions and read/write access to the compl ete inter nal address space. A breakpoi nt
trigger can be answered with a CPU-halt, a monitor call, a data transfer, or/and the
activation of an external signal.
Tracing data can be obt ained via the JTA G interface or via the external bus i nte rface for
increased performance.
The debug interface uses a set of 6 interface signals (4 JTAG lines, 2 break lines) to
communicate with external circuitry. These interface signals are realized as alternate
functions on Port 3 pins.
Complete system emulation is supported by the New Emulation Technology (NET)
interface. Via this full-featured emulation interface (including internal buses, control,
status, and pad signals) the XC164 chip can be connected to a NET carrier chip.
The use of the XC164 production chip together with the carrier chip provides superior
emulation behavior, because the emulation system shows exactly the same functionality
as the production chip (use of the identical silico n).
Data Sheet 25 V2.1, 2003-06
Page 30
XC164
Derivatives
Functional Description
3.6 Capture/Compare Units (CAPCOM1/2)
The CAPCOM units support generation and control of timing sequences on up to
32 channels with a maximum resolution of 1 system clock cycle (8 cycles in staggered
mode). The CAPCOM units are typically used to handle high speed I/O tasks such as
pulse and waveform generation, pulse width modulation (PMW), Digital to Analog (D/A)
conversion, software timing, or time recording relative to external events.
Four 16-bit timers (T0/T1, T7/T8) with reload registers provide two independent time
bases for each capture/compare register array.
The input clock for the timers is programmable to several prescaled values of the i nternal
system clock, or may be derived from an overflow/u nderflow of timer T6 in module GPT2.
This provides a wide range of variation for the timer period and resolution and allows
precise adjustments to the application specific requirements. In addition, external count
inputs for CAPCOM timers T0 and T7 allow event scheduling for the capture/compare
registers relative to external events.
Both of the two capture/compare register arrays contain 16 dual purpose capture/
compare registers, each o f which may be i ndividual ly all ocated to either CAP COM timer
T0 or T1 (T7 or T8, respectively), and programmed for capture or compare function.
12 registers of the CAPCOM2 module have each one port pin associated with it which
serves as an input pin for triggering the capture function, or as an output pin to indicate
the occurrence of a compare event.
Table 6 Compare Modes (CAPCOM1/2)
Compare Modes Function
Mode 0 Interrupt-only compare mode;
several compare interrupts per timer period are possible
Mode 1 Pin toggles on each compare match;
several compare events per timer period are possible
Mode 2 Interrupt-only compare mode;
only one compare interrupt per timer period is generated
Mode 3 Pin set ‘1’ on match; pin reset ‘0’ on compare timer overflow;
only one compare event per timer period is generated
Double Register
Mode
Single Event Mode Generates single edges or pulses;
Two registers operate on one pin;
pin toggles on each compare match;
several compare events per timer period are possible
can be used with any compare mode
Data Sheet 26 V2.1, 2003-06
Page 31
XC164
Derivatives
Functional Description
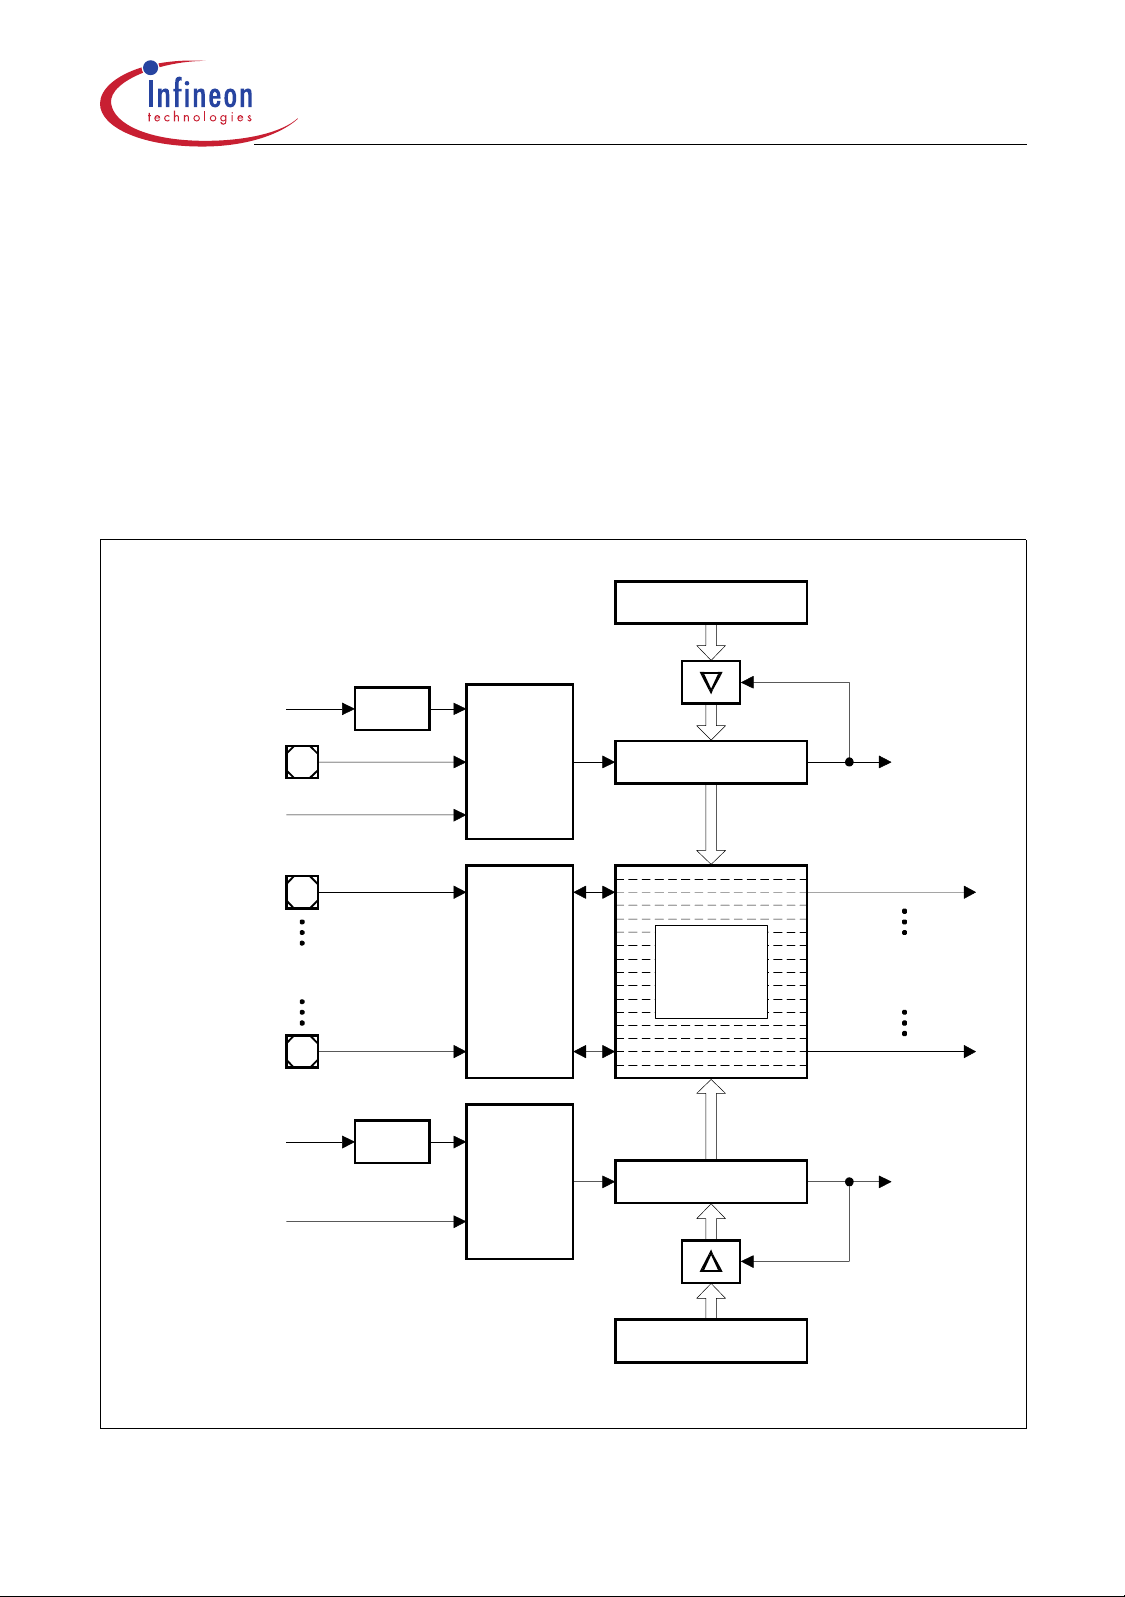
When a capture/compare register has been selected for capture mode, the current
contents of the allocated timer will be latched (‘captured’) into the capture/compare
register in response to an external event at the port pin which is associated with this
register. In addition, a specific interrupt request for this capture/compare register is
generated. Either a posi tive, a negativ e, or both a positive and a negati ve external sign al
transition at the pin can be selected as the triggering event.
The contents of all registers which have been selected for one of the five compare mode s
are continuously compared with the contents of the allocated timers.
When a match occurs between the timer value and the value in a capture/compare
register, specific actions will be taken based on the selected compare mode.
Reload Reg. TxREL
n
f
SYS
TxIN
GPT1 Timer T3
Over/U nderflow
2
: 1
Tx
Inpu t
Control
CAPCOM Timer Tx
In te rr u p t
Request
(T x IR)
CCzIO
Mode
Capture Inputs
Compare Outputs
CCzIO
f
SYS
GPT1 Timer T3
Over/U nderflow
n
2
: 1
Control
(C ap t u re
or
Compare)
Ty
Inpu t
Control
x=0, 7
y=1, 8
n = 0/3 … 10
z = 0 … 31 (for interrupts),
= 16 … 27 (for pins)
Figure 5 CAPCOM1/2 Unit Block Diagram
16-Bit
Capture/
Compare
Registers
CAPCOM Timer Ty
Reload Reg. TyREL
Capture/Compare
Interrupt Requests
(CC z IR)
In te rr u p t
Request
(T y IR)
MCB02143_X4.VSD
Data Sheet 27 V2.1, 2003-06
Page 32
XC164
Derivatives
Functional Description
3.7 The Capture/Compare Unit CAPCOM6
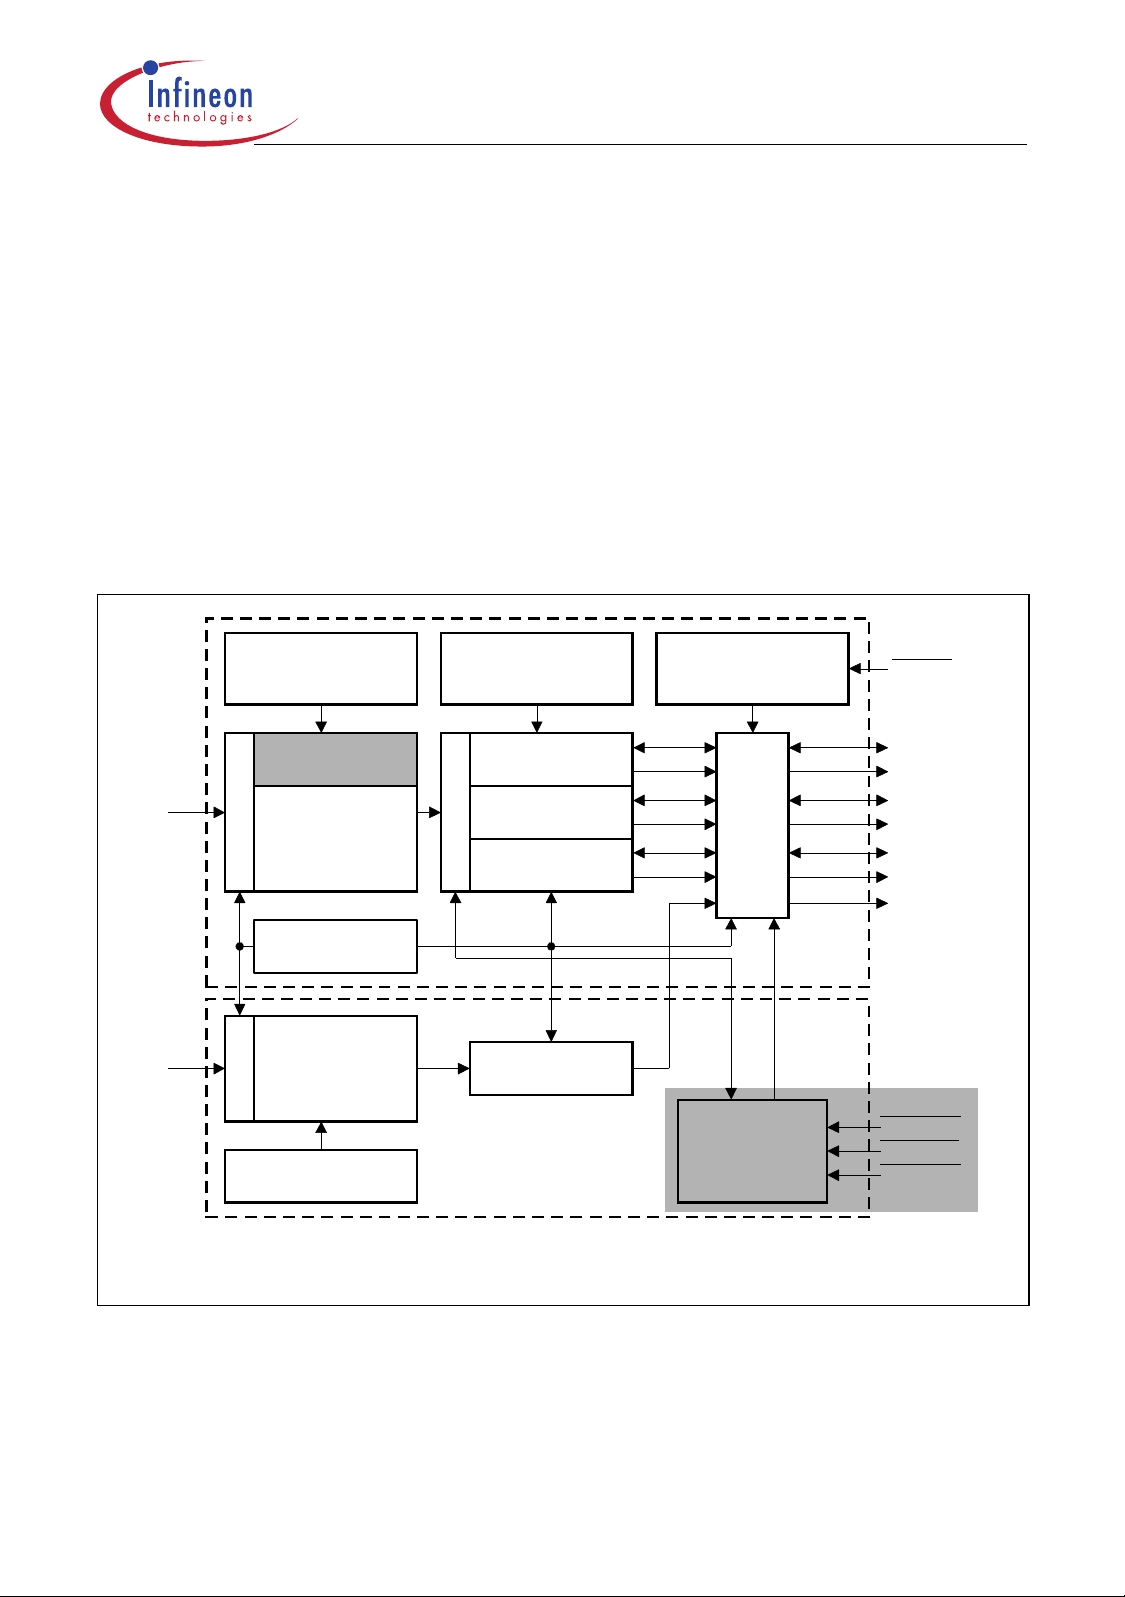
The CAPCOM6 unit supports generation and cont rol of t im ing sequences o n up to three
16-bit capture/compare channels plus one independent 10-bit compare channel.
In compare mode the CAPCOM6 unit provides two output signals per channel which
have inverted polarity and non-overlapping pulse transitions (deadtime control). The
compare channel can generate a single PWM output signal and is further used to
modulate the capture/compare output signals.
In capture mode the contents of compare timer T12 is stored in the capture registers
upon a signal transition at pins CCx.
Compare timers T12 (16-bit) and T13 (10-bit) are free running timers which are clocked
by the prescaled system clock.
Period Register
T12P
Mode
Select Register
CC6MSEL
Trap Register
CTRAP
Offset Register
T12OF
f
CPU
f
CPU
The timer registers (T12, T13) are not directly accessible.
The period and offset registers are loading a value into the timer registers.
Compare
Timer T12
Prescaler
Prescaler
16-Bit
Cntrol Register
CTCON
Compare
Timer T13
10-Bit
Period Register
T13P
CC Channel 0
CC60
CC Channel 1
Control
CC61
CC Channel 2
CC62
Compare Reg ister
CMP13
Port
Control
Logic
Block
Commutation
Control
CC6MCON.H
CC60
COUT60
CC61
COUT61
CC62
COUT62
COUT63
CC6POS0
CC6POS1
CC6POS2
MCB04109
Figure 6 CAPCOM6 Block Diagram
For motor control applications both subunits may generate versatile multichannel PWM
signals which are basically either controlled by compare timer T12 or by a typical hall
sensor pattern at the interrupt inputs (block commutation).
Data Sheet 28 V2.1, 2003-06
Page 33
XC164
Derivatives
Functional Description
3.8 General Purpose Timer (GPT12E) Unit
The GPT12E unit re presents a very flexibl e multifunctional tim er/counter structure which
may be used for many different time related tasks such as event timing and counting,
pulse width and duty cycle measurements, pulse generation, or pulse multiplication.
The GPT12E unit incorporates five 16-bit timers which are organized in two separate
modules, GPT1 and GPT2. Each timer in each module may operate independently in a
number of different modes, or may be concatenated with another timer of the same
module.
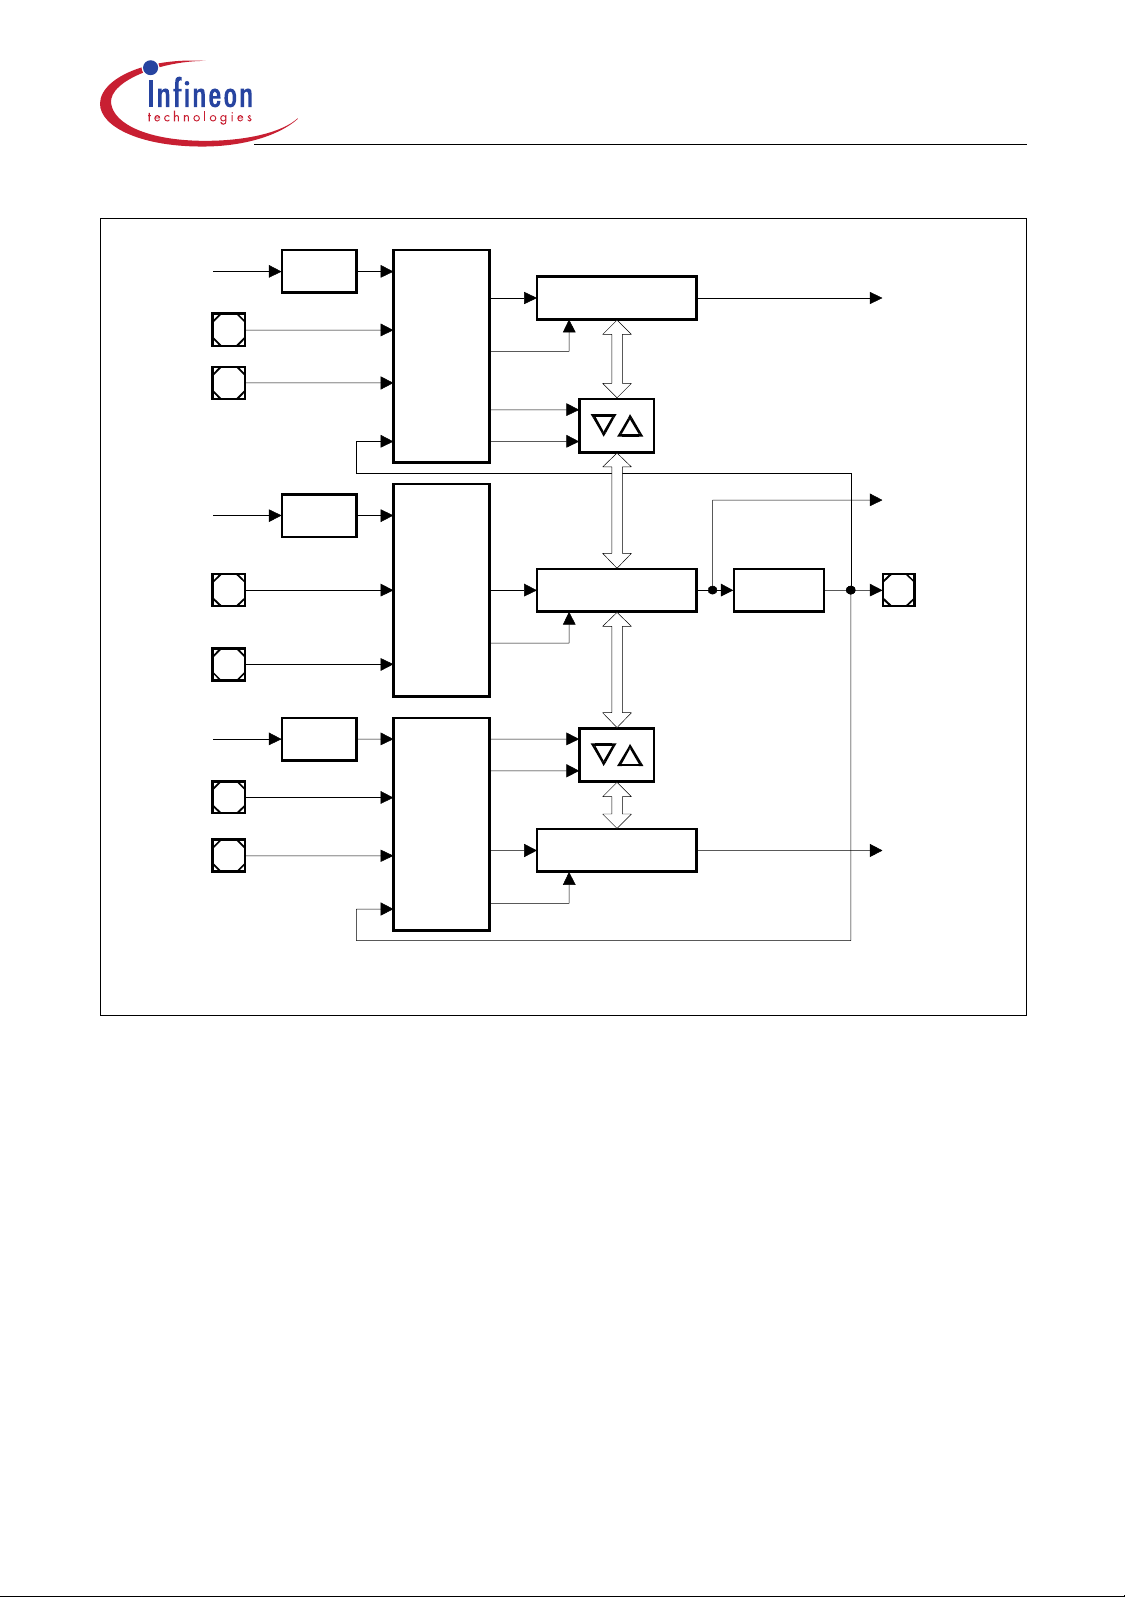
Each of the three timers T2, T3, T4 of module GPT1 can be configured individually for
one of four basic modes of operation, which are Timer, Gated Timer, Counter, and
Incremental Interface Mode. In Timer Mode, the input clock for a timer is derived from
the system clock, divided by a programmable prescaler, while Counter Mode allows a
timer to be clocked in reference to external events.
Pulse width or duty cycle measurement is supported in Gated Timer Mode, where the
operation of a timer is controlled by the ‘gate’ level on an external input pin. For these
purposes, each timer has one associated port pin (TxIN) which serves as gate or clock
input. The maximum resolution of the timers in module GPT1 is 4 system clock cycles.
The count direction (up/down) for each timer is programmable by software or may
additionally be altered dynamically by an external signal on a port pin (TxEUD) to
facilitate e.g. position tracking.
In Incremental Interface Mode the GPT1 timers (T2, T3, T4) can be directly connected
to the incremental position sensor signals A and B via their respective inputs TxIN and
TxEUD. Direction and count signals are internally derived from these two input signals,
so the contents of the respective timer Tx corresponds to the sensor position. The third
position sensor signal TOP0 can be connected to an interrupt input.
Timer T3 has an output toggle latch (T3OTL) which changes its state on each timer overflow/underflow. The state of this latch may be output on pin T3OUT e.g. for time out
monitoring of external hardware components. It may also be used internally to clock
timers T2 and T4 for measuring long time periods with high resolution.
In addition to their basic operating modes, timer s T2 and T4 may be configured as reload
or capture registers for timer T3. When used as capture or reload registers, timers T2
and T4 are stopped. The contents of timer T3 is captured into T2 or T4 in response to a
signal at their associated input pins (TxIN). Time r T3 is re loaded with the content s of T2
or T4 triggered either by an external signal or by a selectable state tra nsition of its toggle
latch T3OTL. When both T2 and T4 are configured to alternately reload T3 on opposite
state transitions of T3OTL with the low and high times of a PWM signal, this signal can
be constantly generated without software intervention.
Data Sheet 29 V2.1, 2003-06
Page 34
XC164
Derivatives
f
SYS
T2IN
T2EUD
f
SYS
T3IN
T3EUD
f
SYS
Functional Description
n
2
: 1
GPT1 Timer T2
T2
Mode
Control
n
2
: 1
T3
Mode
Control
n
2
: 1
U/D
Reload
Capture
Toggle FF
GPT1 Timer T3 T3OTL
U/D
Capture
Reload
In te rr u p t
Request
(T 2 IR)
In te rr u p t
Request
(T 3 IR)
T6O UT
T4IN
T4EUD
T4
Mode
Control
GPT1 Timer T4
U/D
In te rr u p t
Request
(T 4 IR)
Mct04825_xc.vsd
n = 2 … 12
Figure 7 Block Diagram of GPT1
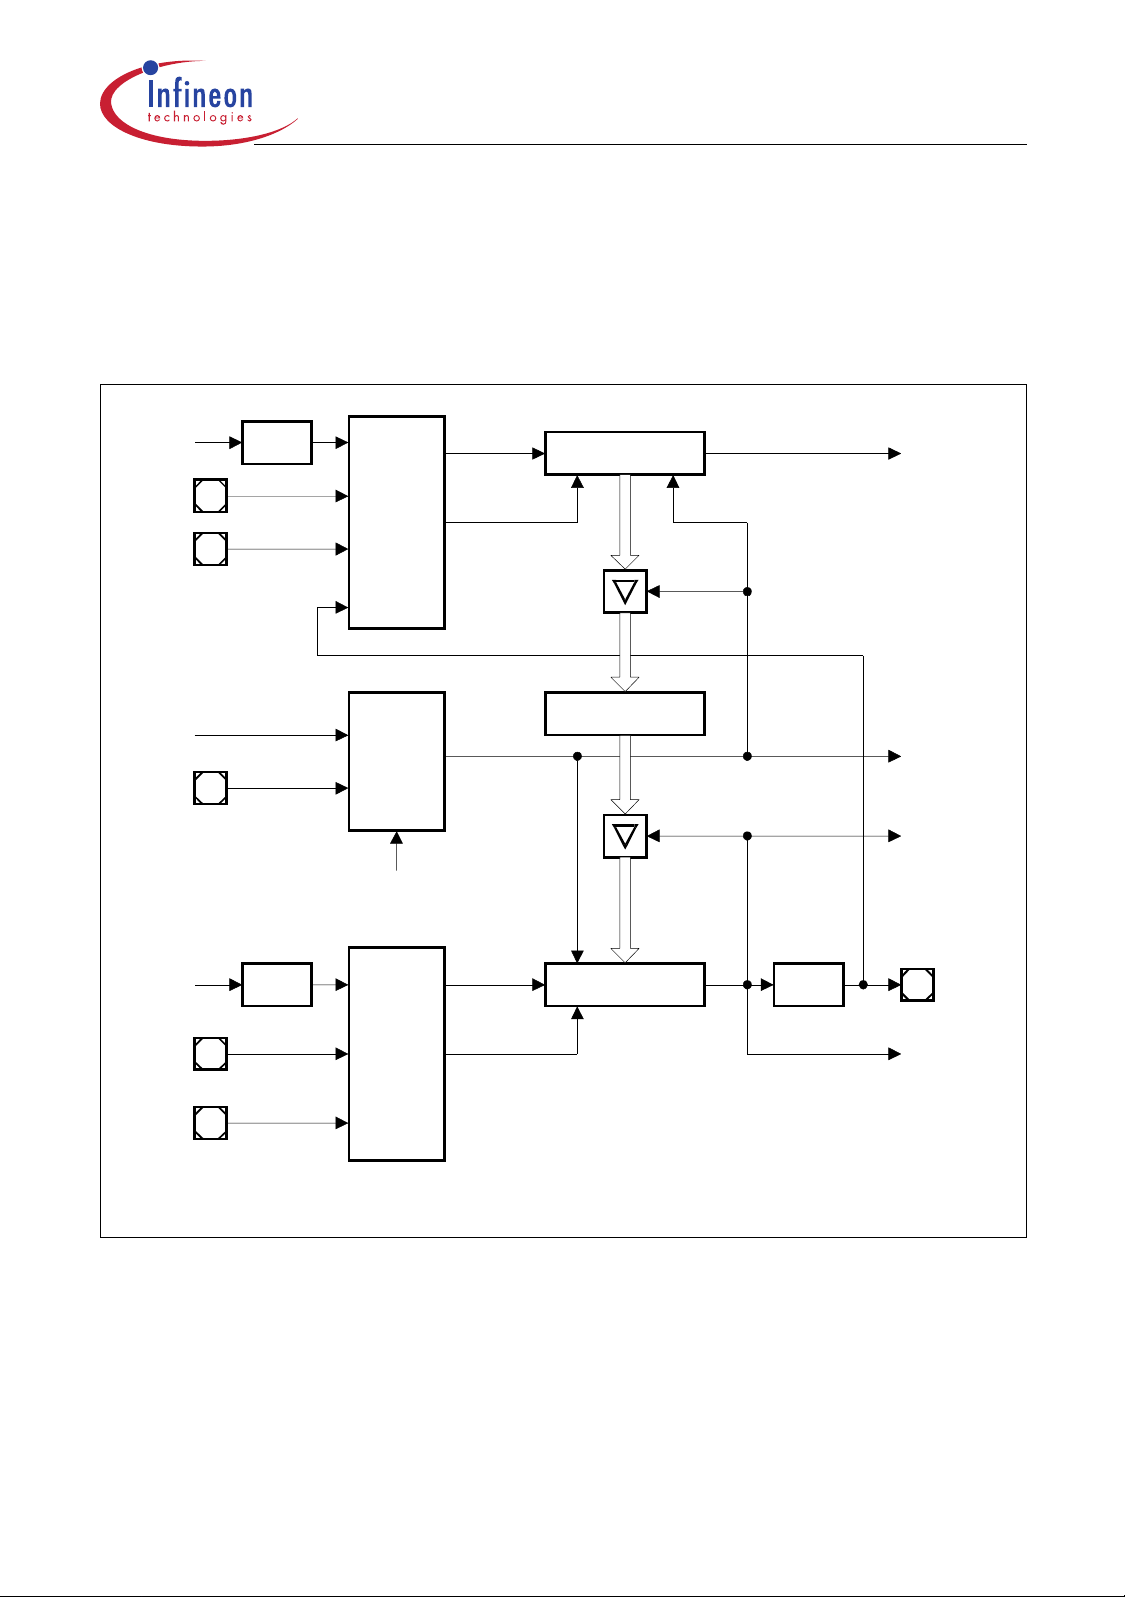
With its maximum resolution of 2 system clock cycles, the GPT2 module provides
precise event control and time measurement. It includes two timers (T5, T6) and a
capture/reload reg ister (CA PREL). B oth t imers can be clocked w ith an input clock which
is derived from th e CPU clock via a pr ogrammable prescaler or with external signals. The
count direction (up/down) for each timer is programmable by software or may
additionally be altered dynamically by an external signal on a port pin (TxEUD).
Concatenation of the timers is supported via the output toggl e latch (T6OTL) o f timer T6,
which changes its state on each timer overflow/underflow.
The state of this latch may be used to clock timer T5, and/or it may be output on pin
T6OUT. The overflows/underflows of timer T6 can additionally be used to clock the
CAPCOM1/2 timers, and to cause a reload from the CAPREL register.
The CAPREL register may capture the contents of timer T5 based on an external sign al
transition on the corresponding port pin (CAPIN), and timer T5 may optionall y be cleared
Data Sheet 30 V2.1, 2003-06
Page 35
XC164
Derivatives
Functional Description
after the capture procedure. This allows the XC164 to measure absolute time differences
or to perform pulse multiplication without software overhead.
The capture trigger (timer T5 to CAPREL) may also be generated upon transitions of
GPT1 timer T3’s inputs T3IN and/or T3EUD. This is especially advantageous when T3
operates in Incremental Interface Mode.
f
SYS
T5IN
T5EUD
T3IN/
T3EUD
CAPIN
n
2
: 1
T5
Mode
Control
MUX
CT3
G PT 2 Time r T5
U/D
GPT2 CAPR EL
Clear
Capture
In te r rup t
Request
(T 5 IR)
In te r rup t
Request
(CRIR)
In te r rup t
Request
(T 6 IR)
n
f
SYS
T6IN
T6EUD
2
: 1
T6
Mode
Control
n = 1 … 11
Figure 8 Block Diagram of GPT2
Clear
G PT 2 Time r T6
U/D
Toggle FF
T6OTL
T6OUT
Other
Modules
Mcb03999_xc.vsd
Data Sheet 31 V2.1, 2003-06
Page 36
XC164
Derivatives
Functional Description
3.9 Real Time Clock
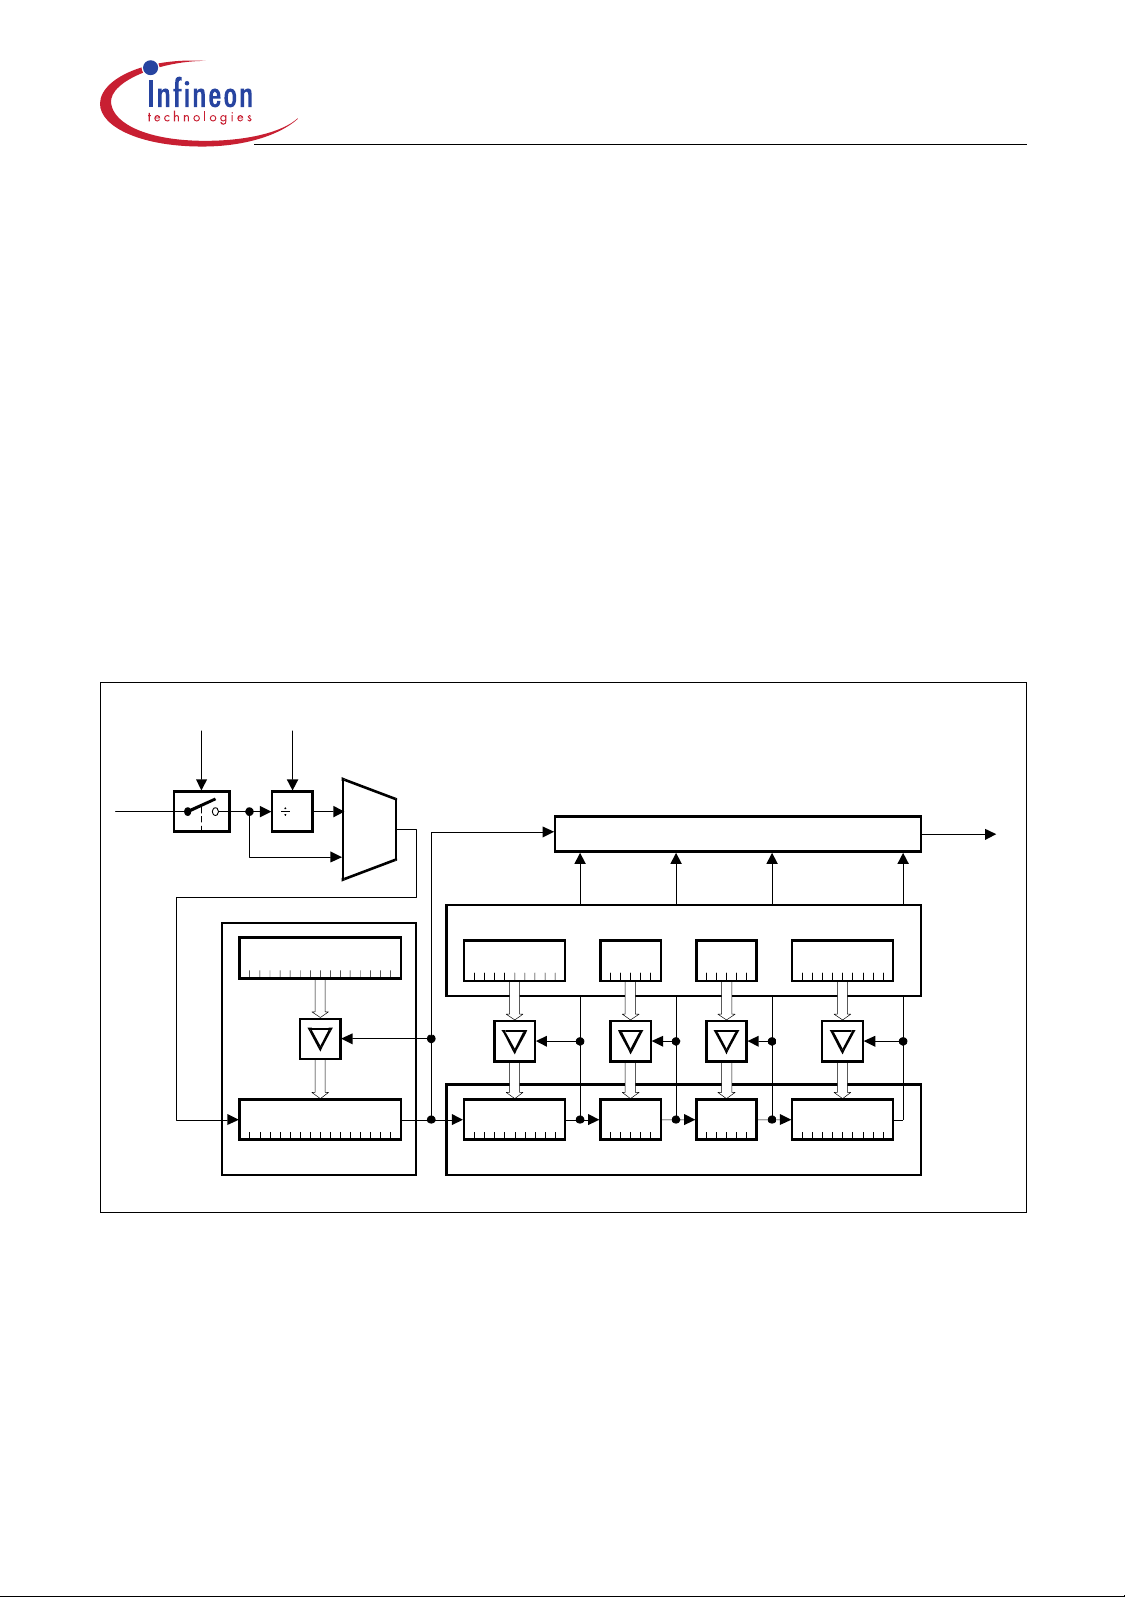
The Real Time Clock (RTC) module of the XC164 is directly clocked via a separate clock
driver with the prescaled on-chip oscillator frequency (f
independent from the selected clock generation mode of the XC164.
The RTC basically consists of a chain of divider blocks:
• a selectable 8:1 divider (on - off)
• the reloadable 16-bit timer T14
• the 32-bit RTC timer block (accessible via registers RTCH and RTCL), made of:
– a reloadable 10-bit timer
– a reloadable 6-bit timer
– a reloadable 6-bit timer
– a reloadable 10-bit timer
All timers count up. Each timer can generate an interrupt request. All requests are
combined to a common node request.
RUN
PRE
RTC
= f
/ 32). It is therefore
OSC
f
RTC
T14REL
T14-Register CN T -R e g iste r
8
T14
1
MUX
0
Inte rru p t Su b N o d e
CNT
IN T 0
10 Bits 6 Bits 6 B its 10 B its
10 Bits 6 Bits 6 B its 10 B its
CNT
INT1
REL-Register
CNT
IN T 2
CNT
IN T3
mcb04805_xc.vsd
RTCINT
Figure 9 RTC Block Diagram
Note: The registers associated with the RTC are not affected by a reset in order to
maintain the correct system time even when intermediate resets are executed.
Data Sheet 32 V2.1, 2003-06
Page 37
XC164
Derivatives
The RTC module can be used for different purposes:
• System clock to determine the current time and date,
optionally during idle mode, sleep mode, and power down mode
• Cyclic time based interrupt, to provide a system time tick independent of CPU
frequency and other resources, e.g. to wake up regularly from idle mode.
• 48-bit timer for long term measurements (maximum timespan is >100 years).
• Alarm interrupt for wake-up on a defined time
Functional Description
Data Sheet 33 V2.1, 2003-06
Page 38
XC164
Derivatives
Functional Description
3.10 A/D Converter
For analog signal measurement, a 10-bit A/D converter with 14 multiplexed input
channels and a sample and hold circ uit has been integr ated on- chip. It uses the method
of successive approximation. The sample time (for loading the capacitors) and the
conversion time is programmable (in two modes) and can thus be adjusted to the
external circuitry. The A/D converter can also operate in 8-bit conversion mode, where
the conversion time is further reduced.
Overrun error detection/protection is provided for the conversion result register
(ADDAT): either an interrupt request will be generated when the result of a previous
conversion has not been read from the result register at the time the next conversion is
complete, or the next conversion is suspended in such a case until the previous result
has been read.
For applications which requ ire l ess analog input channels, the r emai ning channe l inpu ts
can be used as digital input port pins.
The A/D converter of the XC164 supports four different conversion modes. In the
standard Single Channel conversion mode, the analog level on a specified channel is
sampled once and converted to a digital result. In the Single Channel Continuous mode,
the analog level on a specified channel is repeatedly sampled and converted without
software intervention. In the Auto Scan mode, the analog levels on a prespecified
number of channels are sequentially sampled and converted. In the Auto Scan
Continuous mode, the prespecified channels are repeatedly sampled and converted. In
addition, the conversion of a specific channel can be inserted (injected) into a running
sequence without disturbing this sequence. This is called Channel Injection Mode.
The Peripheral Event Controller (PEC) may be used to automatically store the
conversion results into a table in memory for later evaluation, without requiring the
overhead of entering and exiting interrupt routines for each data transfer.
After each reset and also during normal operation the ADC automatically performs
calibration cycles. This automatic self-calibration constantly adjusts the converter to
changing operating conditions (e.g. temperature) and compensates process variations.
These calibration cycles are part of the con version cycle, so they do not affect the norm al
operation of the A/D converter.
In order to decouple analog inputs from digital noise and to avoid input trigger noise
those pins used for analog input can be disconnected from the digital IO or input stages
under software cont rol. This can be selected for each pin sep arately via regi ster P5DIDIS
(Port 5 Digital Input Disable).
The Auto-Power-Down feature of the A/D converter minimizes the power consumption
when no conversion is in progress.
Data Sheet 34 V2.1, 2003-06
Page 39
XC164
Derivatives
Functional Description
3.11 Asynchronous/Synchronous Serial Interfaces (ASC0/ASC1)
The Asynchronous/Synchronous Ser ial Interface s ASC0/ASC1 (USARTs) provide serial
communication with other microcontrollers, processors, terminals or external peripheral
components. They are upward compatible with the serial ports of the Infineon 8-bit
microcontroller families and support full-duplex asynchronous communication and halfduplex synchronous communication. A dedicated baud rate generator with a fractional
divider precisely generates all standard baud rates without oscillator tuning. For
transmission, reception, error handling, and baudrate detection 5 separate interrupt
vectors are provided.
In asynchronous mode, 8- or 9-bit data frames (with optional parity bit) are transmitted
or received, preceded by a start bit and terminated by one or two stop bits. For
multiprocessor communication , a mechanism to distinguish address from data bytes has
been included (8-bit data plus wake-up bit mode). IrDA data transmissions up to
115.2 kbit/s with fixed or programmable IrDA pulse width are supported.
In synchronous mode, bytes (8 bits) are tr ansmitted or r ecei ved synchronously to a sh ift
clock which is generated by the ASC0/1. The LSB is always shifted first.
In both modes, transmission and reception of data is FIFO-buffered. An autobaud
detection unit allows to detect asynchronous data frames with its baudrate and mode
with automatic initialization of the baudrate generator and the mode control bits.
A number of optional ha rdware error detection capabilities has been included to increase
the reliability of data transfers. A parity bit can automatically be generated on
transmission or be checked on reception. Framing error detection allows to recognize
data frames with missing stop bits. An overrun error will be generated, if the last
character received has not been read out of the receive buffer register at the time the
reception of a new character is complete.
Summary of Features
• Full-duplex asynchronous operating modes
– 8- or 9-bit data frames, LSB first, one or two stop bits, parity generation/checking
– Baudrate from 2.5 Mbit/s to 0.6 bit/s (@ 40 MHz)
– Multiprocessor mode for automatic address/data byte detection
– Support for IrDA data transmission/reception up to max. 115.2 kbit/s (@ 40 MHz)
– Loop-back capability
– Auto baudrate detection
• Half-duplex 8-bit synchronous operating mode at 5 Mbit/s to 406.9 bit/s (@ 40 MHz)
• Buffered transmitter/receiver with FIFO support (8 entries per direction)
• Loop-back option available for testing purposes
• Interrupt generation on transmitter buffer empty condition, last bit transmitted
condition, receive buffer full condition, error condition (frame, parity, overrun error),
start and end of an autobaud detection
Note: The serial interface ASC1 is not available in all derivatives of the XC164.
Data Sheet 35 V2.1, 2003-06
Page 40
XC164
Derivatives
Functional Description
3.12 High Speed Synchronous Serial Channels (SSC0/SSC1)
The High Speed Synchronous S erial Channels SSC0/SSC1 support full- duplex and halfduplex synchronous communication. It may be configured so it interfaces with serially
linked peripheral components, full SPI functionality is supported.
A dedicated baud rate generator allows to set up all standard baud rates without
oscillator tuning. For transmission, reception and error handling three separate interrupt
vectors are provided.
The SSC transmits or receives characters of 2 … 16 bits length synchronously to a shift
clock which can be generated by the SSC (master mode) or by an external master (slave
mode). The SSC can start shifting with the LSB or with the MSB and allows the selection
of shifting and latching clock edges as well as the clock polarity.
A number of optional ha rdware error detection capabilities has been included to increase
the reliability of data transfers. Transmit error and receive error supervise the correct
handling of the data buffer. Phase error and baudrate error detect incorrect serial data.
Summary of Features
• Master or Slave mode operation
• Full-duplex or Half-duplex transfers
• Baudrate generation from 20 Mbit/s to 305.18 bit/s (@ 40 MHz)
• Flexible data format
– Programmable number of data bits: 2 to 16 bits
– Programmable shift direction: LSB-first or MSB-first
– Programmable clock polarity: idle low or idle high
– Programmable clock/data phase: data shift with leading or trailing clock edge
• Loop back option available for testing purposes
• Interrupt generation on transm itter buffer empty condition, recei ve buffer full condition,
error condition (receive, phase, baudrate, transmit error)
• Three pin interface with flexible SSC pin configuration
Data Sheet 36 V2.1, 2003-06
Page 41
XC164
Derivatives
Functional Description
3.13 TwinCAN Module
The integrated TwinCAN modul e handles the complete ly auto nomous transm ission and
reception of CAN frames in accordance with the CAN specification V2.0 part B (active),
i.e. the on-chip TwinCAN module can receive and transmit standard frames with 11-bit
identifiers as well as extended frames with 29-bit identifiers.
Two Full-CAN nodes share the TwinCAN module’s resources to optimize the CAN bus
traffic handling and to minimize the CPU load. The module provides up to 32 message
objects, which can be assigned to one of the CAN nodes an d can be combined to FIFOstructures. Each object provides separate masks for acceptance filtering.
The flexible combination of Full-CAN functionality and FIFO architecture reduces the
efforts to fulfill the real-time requirements of complex embedded control applications.
Improved CAN bus monitoring functionality as well as the number of message objects
permit precise and comfortable CAN bus traffic handling.
Gateway functionality allows automatic data exchange between two separate CAN bus
systems, which reduces CPU load and improves the real time behavior of the entire
system.
The bit timing for b oth CAN nodes i s derived from the master clock a nd is programmab le
up to a data rate of 1 Mbit/s. Each CAN node uses two pins of Port 4, Port 7, or Port 9 to
interface to an external bus transceiver. The interface pins are assigned via software.
TwinCAN M odule Kernel
Clock
Control
Address
Decoder
Interrup t
Control
f
CAN
CAN
Node A
M essage
Object
TwinCAN Control
CAN
Node B
Buffer
Figure 10 TwinCAN Module Block Diagram
TXDCA
RXDCA
Port
Control
TXDCB
RXDCB
MCB04515
Data Sheet 37 V2.1, 2003-06
Page 42
XC164
Derivatives
Summary of Features
• CAN functionality according to CAN specification V2.0B active.
• Data transfer rate up to 1 Mbit/s
• Flexible and powerful message transfer control and error handling capabilities
• Full-CAN functionality and Basic CAN functionality for each message object
• 32 flexible message objects
– Assignment to one of the two CAN nodes
– Configuration as transmit object or receive object
– Concatenation to a 2-, 4-, 8-, 16-, or 32-message buffer with FIFO algorithm
– Handling of frames with 11-bit or 29-bit identifiers
– Individual programmable acceptance mask register for filtering for each object
– Monitoring via a frame counter
– Configuration for Remote Monitoring Mode
• Up to eight individually programmable interrupt nodes can be used
• CAN Analyzer Mode for bus monitoring is implemented
Functional Description
Note: When a CAN node has the interface lines assigned t o Port 4, the segment address
output on Port 4 must be limit ed. CS lines can be used to increase the tota l amount
of addressable external memory.
3.14 Watchdog Timer
The Watchdog Timer represents one of the fail-safe mechanisms which have been
implemented to prevent the controller from malfunctioning for longer periods of time.
The Watchdog Timer is always enabled after a reset of the chip, and can be disabled
until the EINIT instruction has been executed (compatible mode), or it can be disabled
and enabled at any time by executing instructions DISWDT and ENWDT (enhanced
mode). Thus, the chip’s start-up procedure is always monitored. The software has to be
designed to restart the Watchdog Timer before it overflows. If, due to hardware or
software related failures, the software fails to do so, the Watchdog Timer overflows and
generates an internal hardware reset and pulls the RSTOUT pin low in order to allow
external hardware components to be reset.
The Watchdog Timer is a 16-bit timer , clocked with the system clock divided by 2/4/128/
256. The high byte of the Watchdog Timer register can be set to a prespecified reload
value (stored in WDTREL) in order to allow further variation of the monitored time
interval. Each time it is serviced by the application software, the high byte of the
Watchdog Timer is reloaded and the low byte is cleared. Thus, time intervals between
13 µs and 419 ms can be monitored (@ 40 MHz).
The default Watchdog Timer interval after reset is 3.28 ms (@ 40 MHz).
Data Sheet 38 V2.1, 2003-06
Page 43
XC164
Derivatives
Functional Description
3.15 Clock Generation
The Clock Generation Unit uses a programmable on-chip PLL with multiple prescalers
to generate the clock signals for the XC164 with high flexibility. The master clock fMC is
the reference clock signal, and is used for TwinCAN and is output to the external system.
The CPU clock f
directly (1:1) or via a 2:1 prescaler (f
The on-chip oscillator can drive an external crystal or accepts an external clock signal.
The oscillator clock frequency can be mu ltiplied by the on -chip P LL (by a prog rammable
factor) or can be divided by a programmable prescaler factor.
If the bypass mode is used (direct drive or prescaler) the PLL can deliver an independent
clock to monitor the clock signal generated by the on-chip oscillator. This PLL cl ock is
independent from the XTAL1 clock. When the expected oscillator clock transitions are
missing the Oscillator Watchdog (OWD) activates the PLL Unlock / OWD interrupt node
and supplies the CPU with an emergency clock, the PLL clock signal. Under these
circumstances the PLL will oscillate with its basic frequency.
The oscillator watch dog can be disabled by switching the PLL off. This r educes power
consumption, but also no interrupt request will be generated in case of a missing
oscillator clock.
and the system clock f
CPU
SYS
= f
are derived from the master clock either
SYS
= fMC / 2). See also Section 5.1.
CPU
Note: At the end of an external reset (EA = ‘0’) the oscillator watchdog may be disabled
via hardware by (externally) pulling the RD line low upon a reset, similar to the
standard reset configuration.
3.16 Parallel Ports
The XC164 provides up to 79 I/O lines which are organized into six input/output ports
and one input port. All port lines are bit-addressable, and all input/output lines are
individually (bit-wis e) program mable as inputs or outputs via direction registers. The I/O
ports are true bidirectional ports which are switched to high impedance state when
configured as inputs. The output drivers of some I/O ports can be configured (pin b y pin)
for push/pull operation or open-drain operation via control registers. During the internal
reset, all port pins are configured as inputs (except for pin RSTOUT
The edge characteristics (shape) and driver characteristics (output current) of the port
drivers can be selected via registers POCONx.
The input threshold of some ports is selectable (TTL or CMOS like), where the special
CMOS like input threshold reduces noise sensitivity due to the input hysteresis. The
input threshold may be selected individually for each byte of the respective ports.
All port lines have programmable alternate input or output functions associated with
them. All por t lines that are no t used for these al ternate functions may be used as general
purpose IO lines.
).
Data Sheet 39 V2.1, 2003-06
Page 44
XC164
Derivatives
Functional Description
Table 7 Summary of the XC164’s Parallel Ports
Port Control Alternate Functions
PORT0 Pad drivers Address/Data lines or data lines
PORT1 Pad drivers Address lines
2)
1)
Capture inputs or compare outputs,
Serial interface lines,
Fast external interrupt inputs
Port 3 Pad drivers,
Open drain,
Input threshold
Timer control signals, serial interface lines,
Optional bus control signal BHE/WRH,
System clock output CLKOUT (or FOUT),
Debug interface lines
Port 4 Pad drivers,
Open drain,
Input threshold
Segment address lines
Optional chip select signals
CAN interface lines
3)
4)
Port 5 --- Analog input channels to the A/D converter,
Timer control signals
Port 9 Pad drivers,
Open drain,
Capture inputs or compare outputs
CAN interface lines
Input threshold
Port 20 Pad drivers,
Open drain
Bus control signals RD, WR/WRL, ALE,
External access enable pin EA,
Reset indication output RSTOUT
1)
For multiplexed bus cycles.
2)
For demultiplexed bus cycles.
3)
For more than 64 Kbytes of external resources.
4)
Can be assigned by software.
4)
Data Sheet 40 V2.1, 2003-06
Page 45
XC164
Derivatives
Functional Description
3.17 Power Management
The XC164 provides several means to control the power it consumes either at a given
time or averaged over a certain timespan. Three mechanisms can be used (partly in
parallel):
• Power Saving Modes switch the XC164 into a special operating mode (control via
instructions).
Idle Mode stops the CPU while the peripherals can continue to operate.
Sleep Mode and Power Down Mode stop all cl ock signals and all operation (R TC may
optionally continue running). Sleep Mode can be terminated by external interrupt
signals.
• Clock Generation Management controls the distribution and the frequency of
internal and external clock signals. While the clock signals for currently inactive parts
of logic are disabled automatically, the user can reduce the XC164’s CPU clock
frequency which drastically reduces the consumed power.
External circuitry can be controlled via the programmable frequency output FOUT.
• Peripheral Management permits temporary disabling of peripheral modules (control
via register SYSCON3). Each peripheral can separately be disabled/enabled.
The on-chip RTC supports intermittend operation of the XC164 by generating cyclic
wake-up signals. This offers full performance to quickly react on action requests while
the intermittend sleep phases greatly reduce the average power consumption of the
system.
Data Sheet 41 V2.1, 2003-06
Page 46
XC164
Derivatives
Functional Description
3.18 Instruction Set Summary
Table 8 lists the instructions of the XC164 in a condensed way.
The various addressing modes that can be used with a specific instruction, the operation
of the instructions, parameters fo r conditional execution of instr uctions, and the opcodes
for each instruction can be found in the “Instruction Set Manual”.
This document also provides a detailled description of each instruction.
Table 8 Instruction Set Summary
Mnemonic Description Bytes
ADD(B) Add word (byte) operands 2 / 4
ADDC(B) Add word (byte) operands with Carry 2 / 4
SUB(B) Subtract word (byte) operands 2 / 4
SUBC(B) Subtract word (byte) operands with Carry 2 / 4
MUL(U) (Un)Signed multiply direct GPR by direct GPR (16-16-bit) 2
DIV(U) (Un)Signed divide regi ster MDL by direct GPR (16-/16 -bit) 2
DIVL(U) (Un)Signed long divide reg. MD by direct GPR (32-/16 -bit) 2
CPL(B) Complement direct word (byte) GPR 2
NEG(B) Negate direct word (byte) GPR 2
AND(B) Bitwise AND, (word/byte operands) 2 / 4
(X)OR(B) Bitwise (exclusive)OR, (word/byte operands) 2 / 4
BCLR / BSET Clear/Set direct bit 2
BMOV(N) Move (negated) direct bit to direct bit 4
BAND / BOR /
BXOR
BCMP Compare direct bit to direct bit 4
BFLDH / BFLDL Bitwise modify masked high/low byte of bit-addressable
CMP(B) Compare word (byte) operands 2 / 4
CMPD1/2 Compare word data to GPR and decrement GPR by 1/2 2 / 4
CMPI1/2 Compare word data to GPR and increment GPR by 1/2 2 / 4
PRIOR Determine number of shift cycles to normalize direct
SHL / SHR Shift left/right direct word GPR 2
ROL / ROR Rotate left/right direct word GPR 2
AND/OR/XOR direct bit with direct bit 4
4
direct word memory with immediate data
2
word GPR and store result in direct word GPR
ASHR Arithmetic (sign bit) shift right direct word GPR 2
MOV(B) Move word (byte) data 2 / 4
MOVBS/Z Move byte operand to word op. with sign/zero extension 2 / 4
Data Sheet 42 V2.1, 2003-06
Page 47
XC164
Derivatives
Table 8 Instruction Set Summary (cont’d)
Mnemonic Description Bytes
JMPA/I/R Jump absolute/indirect/relative if condition is met 4
JMPS Jump absolute to a code segment 4
JB(C) Jump relative if direct bit is set (and clear bit) 4
JNB(S) Jump relative if direct bit is not set (and set bit) 4
CALLA/I/R Call absolute/indirect/relative subroutine if condition is met 4
CALLS Call absolute subroutine in any code segment 4
PCALL Push direct word register onto system stack and call
absolute subroutine
TRAP Call interrupt service routine via immediate trap number 2
PUSH / POP Push/pop direct word register onto/from system stack 2
SCXT Push direct word register onto system stack and update
register with word operand
RET(P) Return from intra-segment subroutine
(and pop direct word register from system stack)
Functional Description
4
4
2
RETS Return from inter-segment subroutine 2
RETI Return from interrupt service subroutine 2
SBRK Software Break 2
SRST Software Reset 4
IDLE Enter Idle Mode 4
PWRDN Enter Power Down Mode (supposes NMI
SRVWDT Service Watchdog Timer 4
DISWDT/ENWDT Disable/Enable Watchdog Timer 4
EINIT Signify End-of-Initialization on RSTOUT-pin 4
ATOMIC Begin ATOMIC sequence 2
EXTR Begin EXTended Register sequence 2
EXTP(R) Begin EXTended Page (and Register) sequence 2 / 4
EXTS(R) Begin EXTended Segment (and Register) sequence 2 / 4
NOP Null operation 2
CoMUL / CoMAC Multiply (and accumulate) 4
CoADD / CoSUB Add / Subtract 4
Co(A)SHR/CoSHL (Arithmetic) Shi ft right / Shift left 4
-pin being low) 4
CoLOAD/STORE Load accumulator / Store MAC register 4
CoCMP/MAX/MIN Compare (maximum/minimum) 4
CoABS / CoRND Absolute value / Round accumulator 4
CoMOV/NEG/NOP Data move / Negate accumulator / Null operation 4
Data Sheet 43 V2.1, 2003-06
Page 48
XC164
Derivatives
Electrical Parameters
4 Electrical Parameters
4.1 Absolute Maximum Ratings
Table 9 Absolute Maximum Rating Parameters
Parameter Symbol Limit Values Unit Notes
min. max.
Storage temperature T
Junction temperature T
Voltage on V
pins with
DDI
respect to ground (VSS)
Voltage on V
pins with
DDP
respect to ground (VSS)
Voltage on any pin with
respect to ground (VSS)
V
V
V
ST
J
DDI
DDP
IN
-65 150 °C–
-40 150 °C under bias
-0.5 3.25 V –
-0.5 6.2 V –
-0.5 V
DDP
V–
+ 0.5
Input current on any pin
– -10 10 mA –
during overload condition
Absolute sum of all input
– – |100| mA –
currents during overload
condition
Note: Stresses above those listed under “Absolute Maximum Ratings” may cause
permanent damage to the device. This is a stress rating only and functional
operation of the device at these or any other conditions above those indicated in
the operational sections of this specification is not implied. Exposure to absolute
maximum rating conditions for extended periods may affect device reliability.
During absolute maximum rating overload conditions (
the voltage on
V
pins with respect to ground (
DDP
V
V
>
V
or
V
IN
) must not exceed the value s
SS
DDP
IN
<
V
SS
defined by the absolute maximum ratings.
4.2 Package Properties
Table 10 Package Parameters (P-TQFP-100-16)
Parameter Symbol Limit Values Unit Notes
)
min. max.
Power dissipation P
Thermal Resistance R
Data Sheet 44 V2.1, 2003-06
DISS
THA
–0.8W–
– 29 K/W Chip-Ambient
Page 49
XC164
Derivatives
Electrical Parameters
4.3 Operating Conditions
The following operating conditions must not be exceeded to ensure correct operation of
the XC164. All parameters specified in the following sections refer to these operating
conditions, unless otherwise noticed.
Table 11 Operating Condition Parameters
Parameter Symbol Limit Values Unit Notes
min. max.
Digital supply voltage for
the core
Digital supply voltage for
IO pads
Supply Voltage Difference ∆V
Digital ground voltage V
Overload current I
V
V
DDI
DDP
SS
OV
DD
2.35 2.7 V Active mode,
f
= f
CPU
CPUmax
4.4 5.5 V Active mode
-0.5 – V V
DDP
- V
DDI
1)
2)
3)
0 V Reference voltage
-5 5 mA Per IO pin
4)5)
-2 5 mA Per analog input
4)5)
pin
Overload current coupling
factor for analog inputs
Overload current coupling
factor for digital I/O pins
Absolute sum of overload
6)
K
OVA
–1.0 × 10⁻⁴– IOV > 0
–1.5 × 10⁻³– IOV < 0
6)
K
OVD
–5.0 × 10⁻³– IOV > 0
–1.0 × 10⁻²– IOV < 0
Σ|IOV|– 50 mA
5)
currents
External Load
Capacitance
Ambient temperature T
C
L
– 50 pF Pin drivers in
default mode
A
070°C SAB-XC164 …
-40 85 °C SAF-XC164 …
-40 125 °C SAK-XC164 …
1)
f
2)
External circuitry must guarantee low level at the RSTIN pin at least until both power supply voltages have
reached the operating level.
3)
This limitation must be fulfi lled under all operatin g conditions including po wer-ramp-up, power-ramp-down, and
power-save modes.
= 40 MHz for devices marked …40F, f
CPUmax
= 20 MHz for devices marked …20F.
CPUmax
7)
Data Sheet 45 V2.1, 2003-06
Page 50
XC164
Derivatives
4)
Overload conditions occur if the standard operating conditions are exceeded, i.e. the voltage on any pin
V
> V
exceeds the specified range:
of input overload currents on all pins may not exceed 50mA. The supply voltages must remain within the
specified limits.
Proper operation is not guaranteed if overload conditions occur on functional pins such as XTAL1, RD
etc.
5)
Not 100% tested, guaranteed by design and characterization.
6)
An ov er l o ad c u rr en t ( IOV) through a pin injects a certain error current (I
current adds to th e respect ive pin’ s leakage cu rrent (
current and is defi ned by the ove r loa d cou pli ng fac tor
compared to the polarity of the overload current that produces it.
The total cur rent thr ough a pin i s |
voltage on analog inputs.
7)
The timing is valid for pin drivers opera ting in default current mode (sele cted after res et). R edu cin g the ou tput
current may lead to increased delays or reduced driving capability (
OV
I
TOT
+ 0.5 V (IOV>0) or VOV< VSS - 0.5 V (IOV< 0). The absolute sum
DDP
I
). The amount of error current depe nds on the overl oad
OZ
K
. The polarity of the inj ected error cur rent is inve r se
OV
| = |IOZ| + (|IOV| × KOV). The additi onal er ror cu rrent may d istor t the in put
INJ
C
).
L
Electrical Parameters
, WR,
) into the adjacent pins. This error
4.4 Parameter Interpretation
The parameters listed in the following partly represent the characteristics of the XC164
and partly its demands on the system. To aid in interpreting the parameters right, when
evaluating them for a design, they are marked in column “Symbol”:
CC (Controller Characteristics):
The logic of the XC164 will provide signals with the respective characteristics.
SR (System Requirement):
The external system must provide signals with the respective characteristics to the
XC164.
Data Sheet 46 V2.1, 2003-06
Page 51
XC164
Derivatives
Electrical Parameters
4.5 DC Parameters
DC Characteristics
(Operating Conditions apply)
Parameter Symbol Limit Values Unit Test Condition
Input low voltage TTL
(all except XTAL1)
Input low voltage XTAL1 V
Input low voltage
(Special Threshold)
Input high voltage TTL
(all except XTAL1)
Input high voltage XTAL1 V
Input high voltage
(Special Threshold)
1)
min. max.
V
SR -0.5 0.2×V
IL
SR -0.5 0.3 ×V
ILC
V
SR -0.5 0.45
ILS
V
SR 0.2×V
IH
+ 0.9
SR 0.7
IHC
× V
DDI
V
SR 0.8×V
IHS
- 0.2
DDP
DDP
- 0.1
× V
V
DDP
+ 0.5
V
DDI
+ 0.5
V
DDP
+ 0.5
DDP
V–
DDP
V–
DDI
V
V–
V–
V–
2)
Input Hysteresis
(Special Threshold)
Output low voltage V
Output high voltage
Input leakage curr ent (Port 5)
5)
6)
Input leakage current (all
other)
Configuration pull-up current
6)
7)
HYS 0.04
× V
DDP
–VV
Series
DDP
resistance = 0 Ω
CC – 1.0 V IOL ≤ I
OL
–0.45VIOL ≤ I
V
OH
CC V
DDP
–VIOH ≥ I
- 1.0
V
DDP
–VIOH ≥ I
- 0.45
I
CC – ±300 nA 0 V < VIN < V
OZ1
T
A
±200 nA 0 V < VIN < V
T
A
I
CC – ±500 nA 0.45 V < VIN <
OZ2
V
DDP
CPUH
CPUL
8)
–-10µA VIN = V
9)
-100 – µA VIN = V
I
I
in [V],
OLmax
OLnom
OHmax
OHnom
≤ 125 °C
≤ 85 °C
IHmin
ILmax
12)
3)
3) 4)
3)
3) 4)
DDP,
DDP,
Data Sheet 47 V2.1, 2003-06
Page 52
XC164
Derivatives
Electrical Parameters
DC Characteristics (cont’d)
(Operating Conditions apply)
1)
Parameter Symbol Limit Values Unit Test Condition
min. max.
Configuration pull-down
current
Level inactive hold current
Level active hold current
10)
11)
11)
XTAL1 input current I
Pin capacitance
12)
8)
I
CPDL
I
CPDH
I
LHI
8)
–10µA VIN = V
9)
120 – µA VIN = V
–-10µA V
0.5 × V
9)
I
LHA
IL
C
IO
-100 – µA V
CC – ±20 µA0 V < VIN < V
CC – 10 pF
OUT
OUT
ILmax
IHmin
=
DDP
= 0.45 V
DDI
(digital inputs/outputs)
1)
Keeping signal levels within the limits specified in this table, ensures operation without overload conditions.
I
For signal levels outside these specifications, also refer to the specification of the overload current
2)
This parameter is tested for P2, P3, P4, P9.
3)
The maximum deliverable output current of a port driver depends on the selected output driver mode, see
Table 12, Current Limits for Port Output Drivers. The limit for pin groups must be respected.
4)
As a rule, with decreasing output current the output levels approach the respective supply level (V
VOH→V
5)
This specification is not valid for outputs which are switched to open drain mode. In this case the respective
output will float and the voltage results from the external circuitry.
6)
An additional error current (I
the definition of the overl oad cou pli ng factor
7)
This specification is valid during Reset for configuration on RD, WR, EA, PORT0.
8)
The maximum current may be drawn while the respective signal line remains inactive.
9)
The minimum current must be drawn to drive the respective signal line active.
10)
This specification is valid during Reset for configuration on ALE.
11)
This specification is valid during Reset for pins P4.3-0, which can act as CS outputs.
12)
Not 100% tested, guaranteed by design and characterization.
). However, only the levels for nominal output currents are guaranteed.
DDP
) will flow if an overload current flows through an adjacent pin. Please refer to
INJ
K
.
OV
.
OV
OL→VSS
,
Data Sheet 48 V2.1, 2003-06
Page 53
XC164
Derivatives
Electrical Parameters
Table 12 Current Limits for Port Output Drivers
Port Output Driver
Mode
Maximum Output Current
(I
OLmax
, -I
OHmax
1)
)
Nominal Output Current
(I
OLnom
, -I
OHnom
)
Strong driver 10 mA 2.5 mA
Medium driver 4.0 mA 1.0 mA
Weak driver 0.5 mA 0.1 mA
1)
An output current above |I
For any group of 16 neighboring port output pins the total output current in each direction (Σ
must remain below 50 mA.
| may be drawn from up to three pins at the same time.
OXnom
I
and Σ-IOH)
OL
Power Consumption XC164
(Operating Conditions apply)
Parameter Symbol Limit Values Unit Test Condition
min. max.
Power supply current (active)
with all peripherals active
Pad supply current I
Idle mode supply current
with all peripherals active
Sleep and Power-down mode
supply current caused by
leakage
4)
I
DDI
DDP
I
IDX
I
PDL
5)
– 15 +
2.6 × f
mA
CPU
–5 mA
– 15 +
1.2 × f
– 128,000
-α
× e
mA
CPU
mA V
1)
f
in [MHz]
CPU
3)
f
in [MHz]
CPU
DDI=VDDImax
T
in [°C]
J
α =
2)
2)
6)
4670/(273+TJ)
Sleep and Power-down mode
supply current caused by
leakage and the RTC running,
clocked by the main oscillator
4)
I
PDM
7)
– 0.6 +
0.02×f
+ I
PDL
OSC
mA V
DDI=VDDImax
f
in [MHz]
OSC
1)
During Flash programming or erase operations the supply current is increased by max. 5 mA.
2)
The supply current is a function of the operating frequency. This dependency is illustr a ted in Figure 11.
These paramet ers are tested at
V
all inputs at
3)
The pad supply voltage pins (V
amount of current is consumed even though no outputs are driven, because the drivers’ input stages are
switched and also the Flash module draws some power from the
4)
The total supply current in Sleep and Power-down mode is the sum of the temperature dependent leakage
current and the frequency dependent current for RTC and main oscillator (if active).
Data Sheet 49 V2.1, 2003-06
or VIH.
IL
V
DDP
and ma ximum C PU c lock frequen cy w ith al l outp uts di sconn ected and
DDImax
) mainly provides the current consumed by the pin output drivers. A small
V
supply.
DDP
Page 54
XC164
Derivatives
5)
This parameter is determined mainly by the transistor leakage currents. This current heavily depends on the
T
junction tempera ture (see Figure 13). The jun ction tempe rature
is the same as the ambient tempe ratur e T
J
Electrical Parameters
if no current flows through the port output drivers. Otherwise, the resulting temperature difference must be
taken into account.
6)
All inputs ( in clu din g pin s c onfi gured as inputs) a t 0 V to 0.1 V or at V
pins configured as outputs) disconnected. This parameter is tested at 25 °C and is valid for
7)
This parame ter is d etermine d main ly by the c urren t cons umed by the osci llat or swi tched t o low gain mo de (see
- 0.1 V to V
DDP
, all outputs (inc lud ing
DDP
T
≥ 25 °C.
J
Figure 12). This current, however, is influenced by the external oscillator circuitry (crystal, capacitors). The
given values refer to a typical circuitry and may change in case of a not optimized external oscillator circuitry.
A
Data Sheet 50 V2.1, 2003-06
Page 55
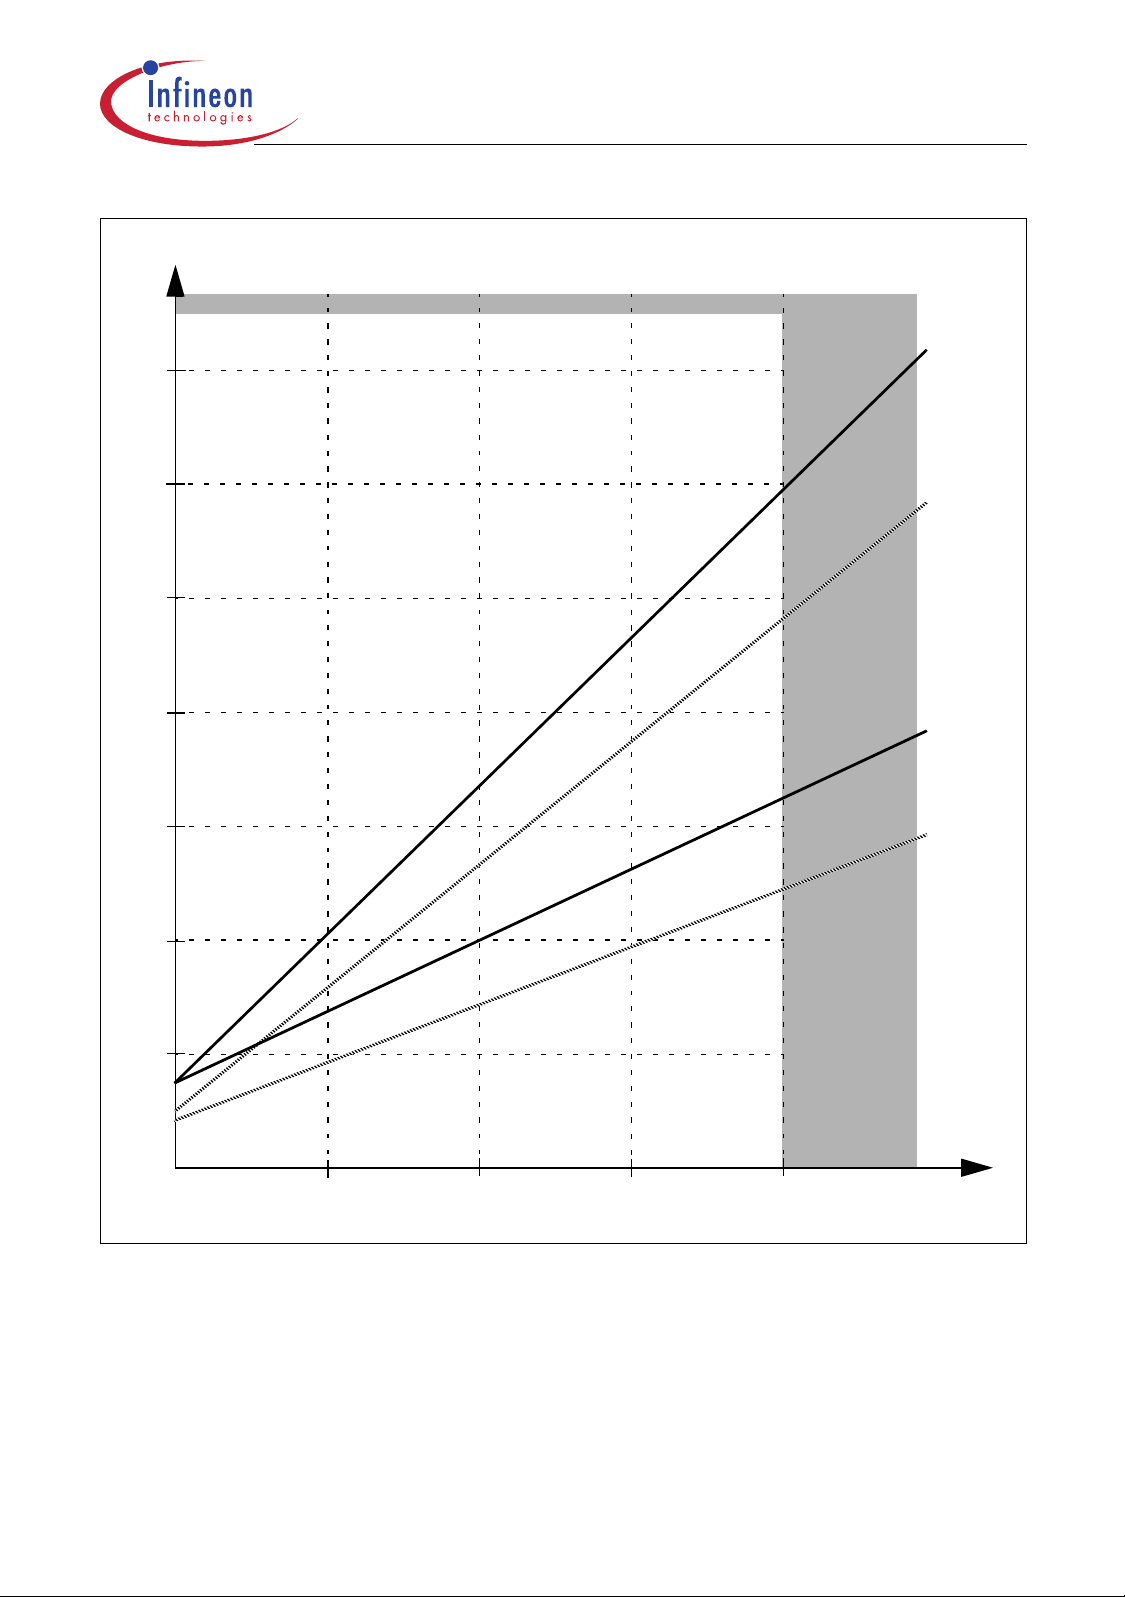
XC164
Derivatives
140
120
100
I [mA]
80
Electrical Parameters
I
DDImax
I
DDItyp
I
IDXmax
60
40
20
10 20 30 40
f
CPU
Figure 11 Supply/Idle Current as a Function of Operating Frequency
I
IDXtyp
[MHz]
Data Sheet 51 V2.1, 2003-06
Page 56
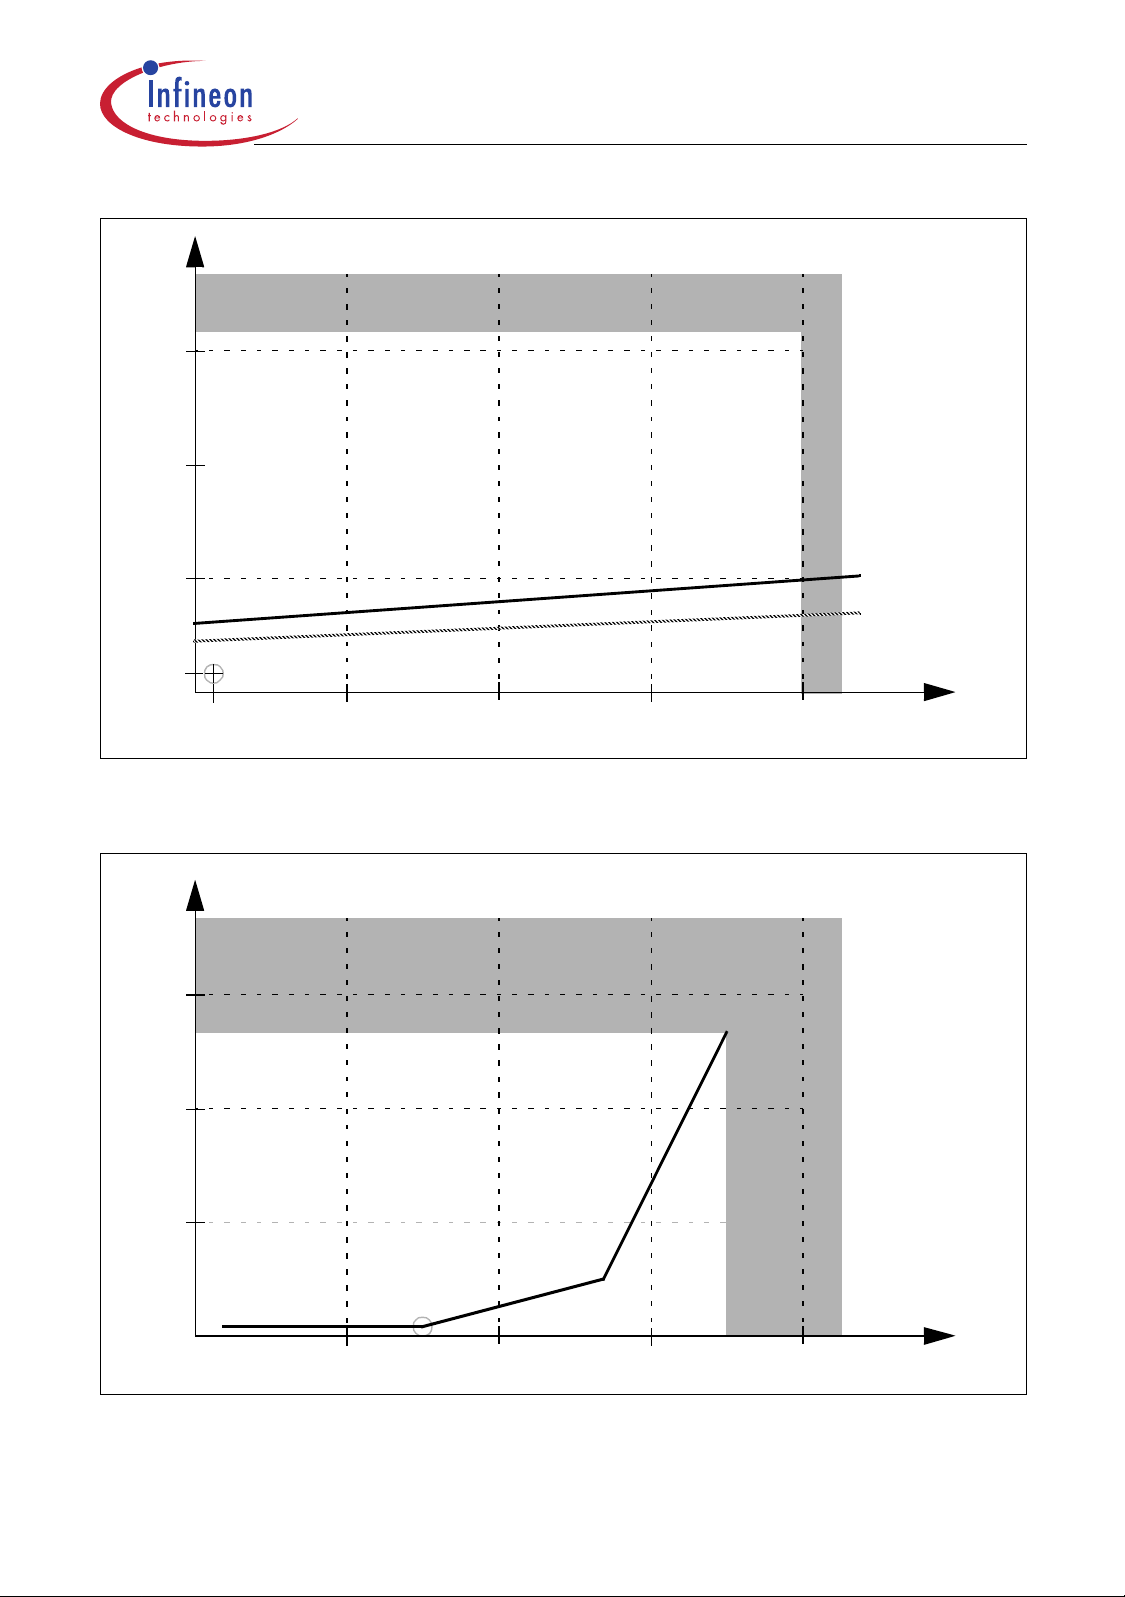
XC164
Derivatives
I [mA]
3.0
2.0
1.0
0.1
32 kHz
I
PDAmax
Electrical Parameters
4 8 12 16
I
PDMmax
I
PDMtyp
f
[MHz]
OSC
Figure 12 Sleep and Power Down Supply Current due to RTC and Oscillator
running, as a Function of Oscillator Frequency
I
PDO
[mA]
1.5
1.0
0.5
-50
0 50 100 150
T
[°C]
J
Figure 13 Sleep and Power Down Leakage Supply Current as a Function of
Temperature
Data Sheet 52 V2.1, 2003-06
Page 57
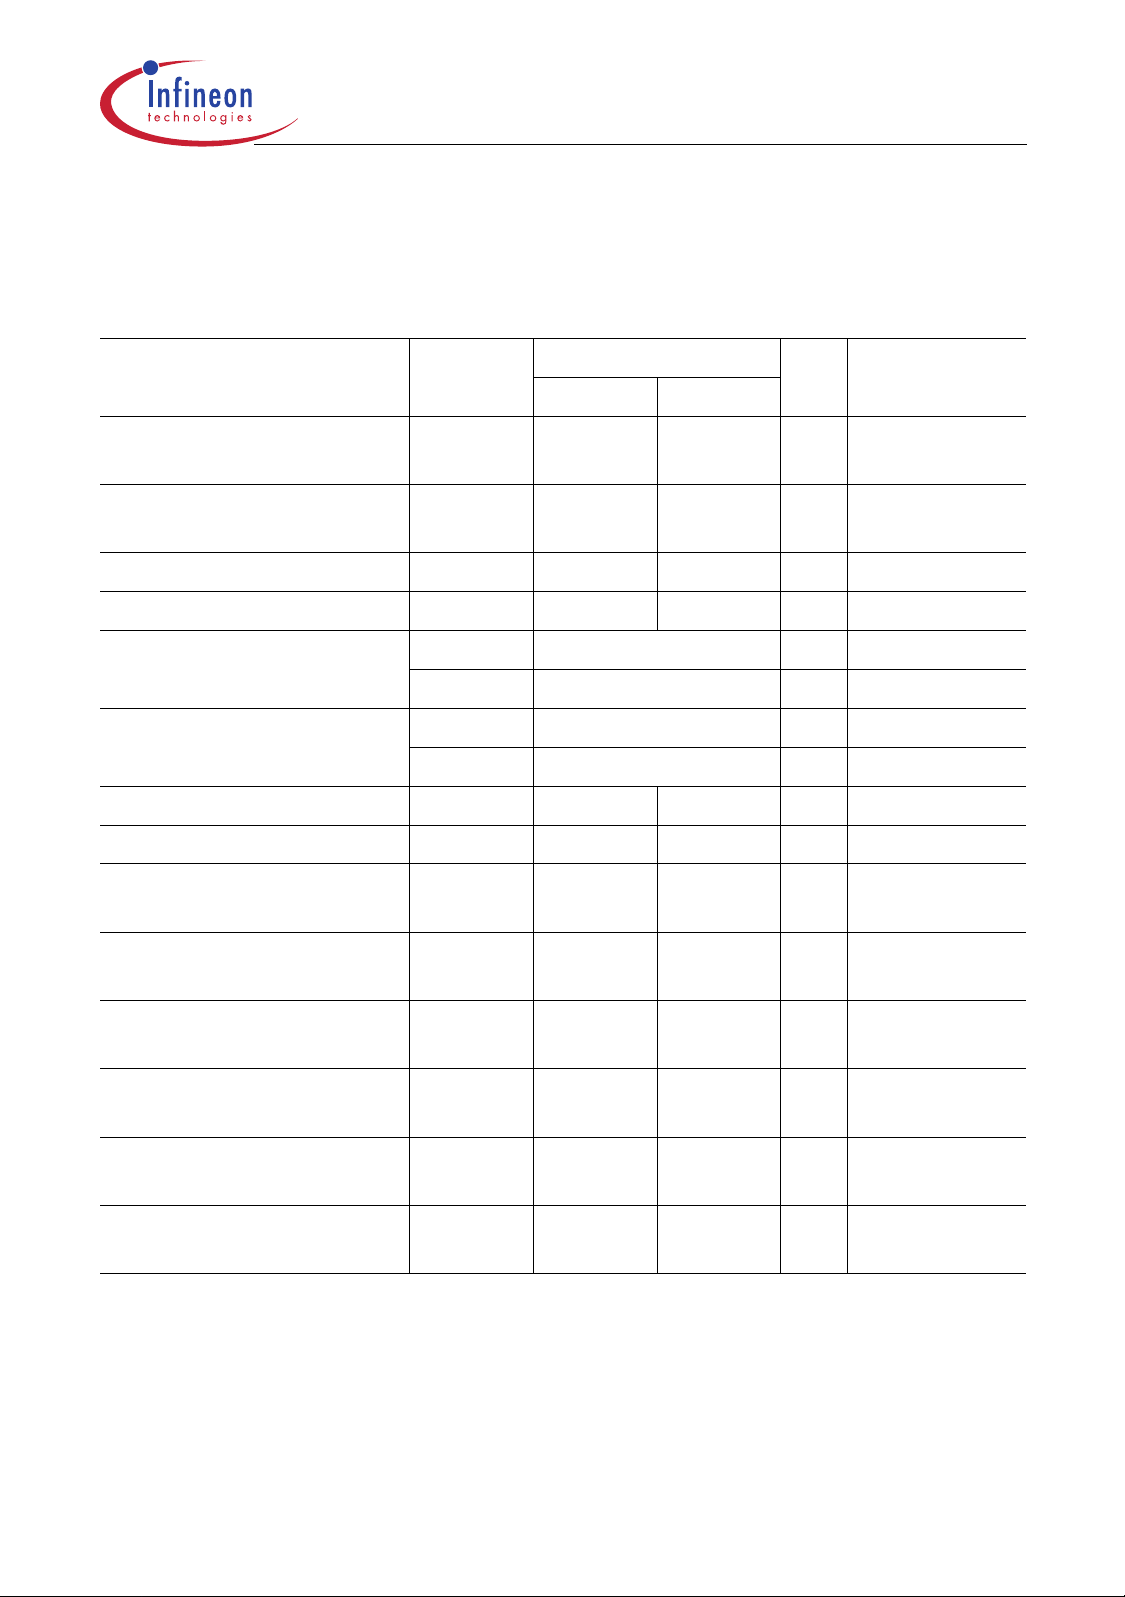
XC164
Derivatives
Electrical Parameters
4.6 A/D Converter Characteristics
Table 13 A/D Converter Characteristics
(Operating Conditions apply)
Parameter Symbol Limit Values Unit Test
min. max.
Analog reference supply V
Analog reference ground V
AREF
AGND
4.5 V
SR
V
SS
DDP
V
+ 0.1
- 0.1 VSS + 0.1 V
SR
Analog input voltage range V
Basic clock frequency f
Conversion time for 10-bit
4)
result
Conversion time for 8-bit
7)
result
t
t
t
t
Calibration time after reset t
BC
C10P
C10
C8P
C8
CAL
AIN
SR V
AGND
V
AREF
0.5 20 MHz
CC 52×tBC + tS + 6×t
CC 40×tBC + tS + 6×t
CC 44×tBC + tS + 6×t
CC 32×tBC + tS + 6×t
CC 484 11,696 tBC
V
– Post-calibr. on
SYS
– Post-calibr. off
SYS
– Post-calibr. on
SYS
– Post-calibr. off
SYS
Total unadjusted error TUE CC – ±2LSB
Total capacitance
of an analog input
Switched capacitance
of an analog input
Resistance of
the analog input path
Total capacitance
of the reference input
Switched capacitance
of the reference input
Resistance of
the reference input path
C
AINT
C
AINS
R
AIN
C
AREFT
C
AREFS
R
AREF
–15pF
CC
–10pF
CC
–2kΩ
CC
–20pF
CC
–15pF
CC
–1kΩ
CC
Condition
1)
2)
3)
5)
1)
6)
6)
6)
6)
6)
6)
Data Sheet 53 V2.1, 2003-06
Page 58
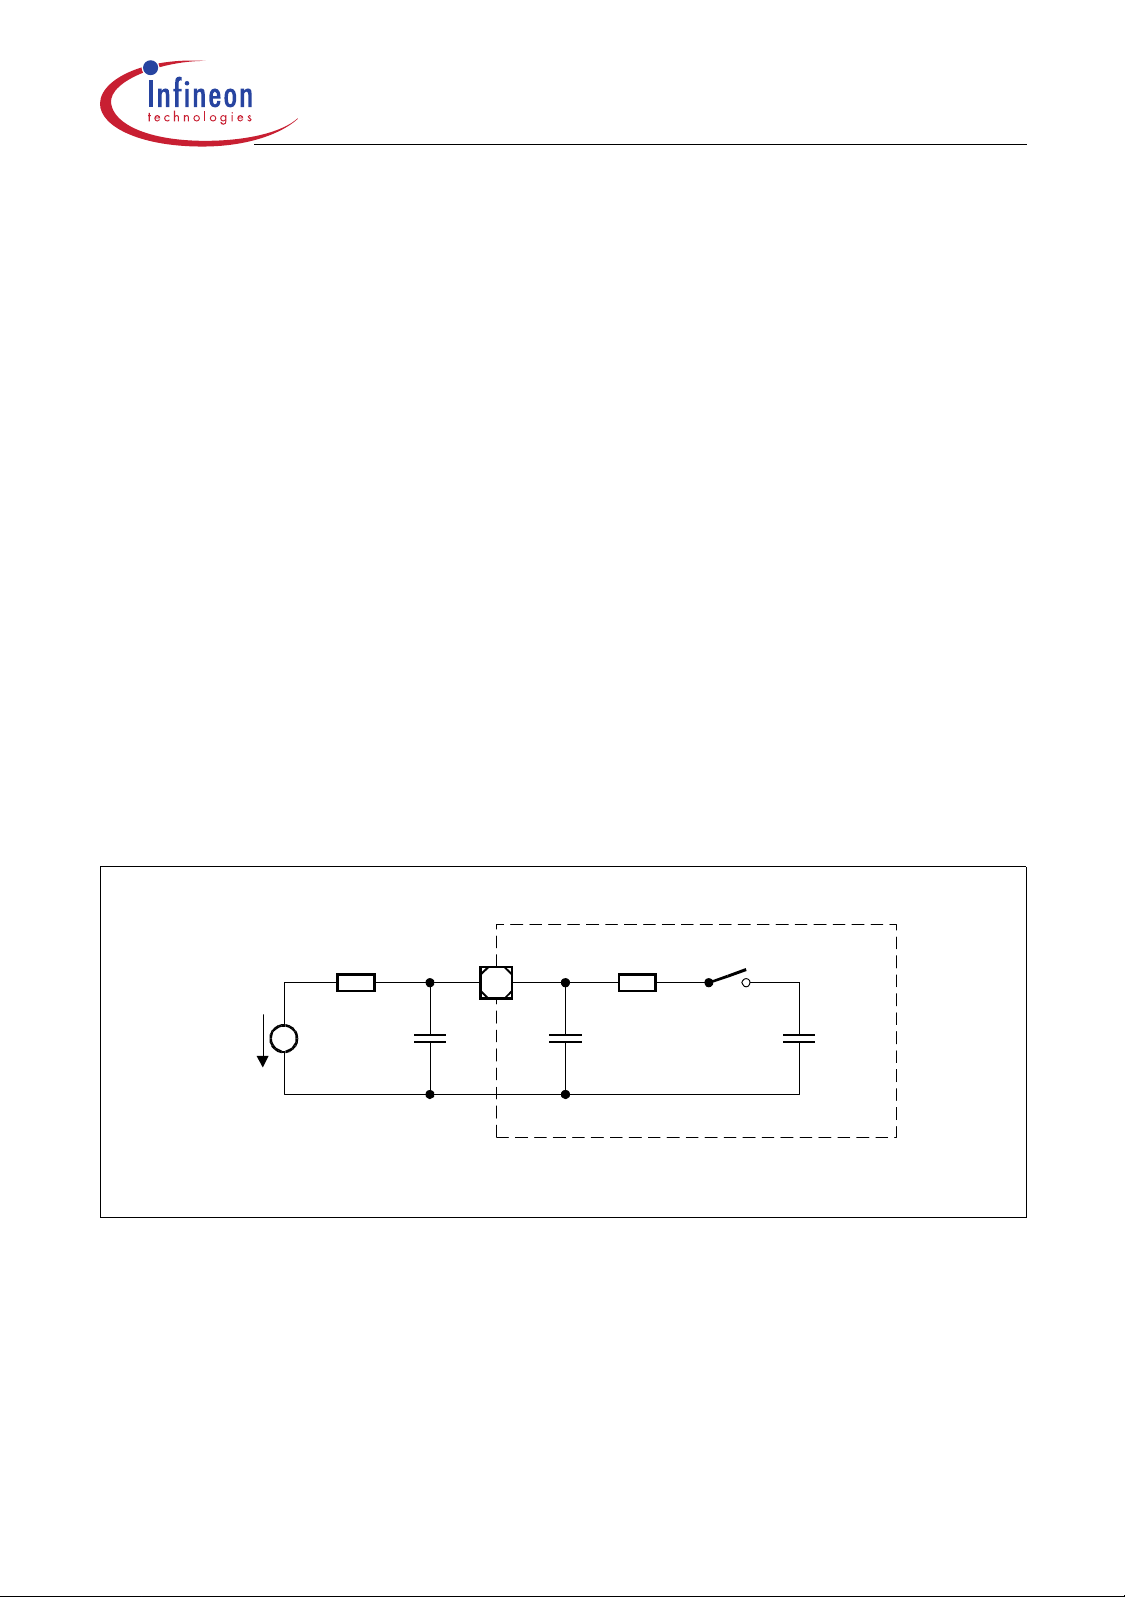
XC164
Derivatives
1)
TUE is tested at V
AREF
= V
DDP
+0.1V, V
= 0 V. It is guaranteed by design for all other voltages within
AGND
Electrical Parameters
the defined voltage range.
V
If the analog reference supply voltage drops below 4.5V (i.e.
V
voltage by up to 0.2V (i.e.
AREF
= V
+ 0.2 V) the maxi mum T UE is incre ase d to ±3 LSB. This range is not
DDP
≥ 4.0 V) or exceeds the power supply
AREF
100% tested.
The s pec if i e d T UE is gua r an te ed on l y, if t h e a bs olu t e su m of inp u t ov erl o ad cu rr e nts on Po rt 5 pi ns ( se e
specification) does not exceed 10 mA, and if V
AREF
and V
remain stable during the respective period of
AGND
time. During the reset calibration sequence the maximum TUE may be ±4 LSB.
2)
V
may exceed V
AIN
these cases will be X000
3)
The limit val ues for f
4)
This parameter includes the sample time tS, the time for determining the digi tal r esult and the time to load the
result register with the conversion result (
Values for the basic clock
When the post-calibration is switched off, the conversion time is reduced by 12 x
5)
The actual duration of the reset calibration depends on the noise on the reference signal. Conversions
or V
AGND
or X3FFH, respectively.
H
must not be excee ded when sel ecting the per iphe ral fr equenc y and the ADCTC setti ng.
BC
t
BC
up to the absolute maximum ratings. However, the conversion result in
AREF
t
SYS
= 1 / f
SYS
).
depend on programming and can be taken from Table 14.
t
BC
executed during the reset calibration increase the calibration time. The TUE for those conversions may be
increased.
6)
Not 100% tested, guaranteed by design and characterization.
The given parameter values cover the complete operating range. Under relaxed operating conditions
(temperatur e, su ppl y vo ltage) reduced va lue s ca n be use d for cal cul atio ns . At room temp er at ure and nominal
supply voltage the following typical values can be used:
C
AINTtyp
= 12 pF, C
AINStyp
= 7 pF, R
AINtyp
= 1.5 kΩ, C
AREFTtyp
= 15 pF, C
AREFStyp
= 13 pF, R
AREFtyp
= 0.7 kΩ.
I
OV
R
Source
V
=
AIN
C
Ext
C
R
AINT
AIN, On
-
C
AINS
A/D Converter
C
AINS
mcs04879_p.vsd
Figure 14 Equivalent Circuitry for Analog Inputs
Data Sheet 54 V2.1, 2003-06
Page 59
XC164
Derivatives
Electrical Parameters
Sample time and conversion time of the XC164’s A/D Converter are programmable. In
compatibility mode, the above timing can be calculated using Table 14.
The limit values for fBC must not be exceeded when selecting ADCTC.
Table 14 A/D Converter Computation Table
ADCON.15|14
(ADCTC)
00 f
01 f
10 f
11 f
1)
These selections are available in compatibility mode. An improved mechanism to control the ADC input clock
can be selected.
A/D Converter
Basic Clock fBC
/ 4 00 tBC × 8
SYS
/ 2 01 tBC × 16
SYS
/ 16 10 tBC × 32
SYS
/ 8 11 tBC × 64
SYS
ADCON.13|12
(ADSTC)
1)
Sample time
t
S
Converter Timing Example:
Assumptions: f
Basic clock f
Sample time t
SYS
BC
S
= 40 MHz (i.e. t
= f
/ 2 = 20 MHz, i.e. tBC = 50 ns.
SYS
SYS
= tBC × 8 = 400 ns.
= 25 ns), ADCTC = ‘01’, ADSTC = ‘00’.
Conversion 10-bit:
With post-calibr. t
Post-calibr. off t
Conversion 8-bit:
With post-calibr. t
Post-calibr. off t
C10P
C10
C8P
C8
= 52 × tBC + tS + 6 × t
= 40 × tBC + tS + 6 × t
= 44 × tBC + tS + 6 × t
= 32 × tBC + tS + 6 × t
= (2600 + 400 + 150) ns = 3.15 µs.
SYS
= (2000 + 400 + 150) ns = 2.55 µs.
SYS
= (2200 + 400 + 150) ns = 2.75 µs.
SYS
= (1600 + 400 + 150) ns = 2.15 µs.
SYS
Data Sheet 55 V2.1, 2003-06
Page 60
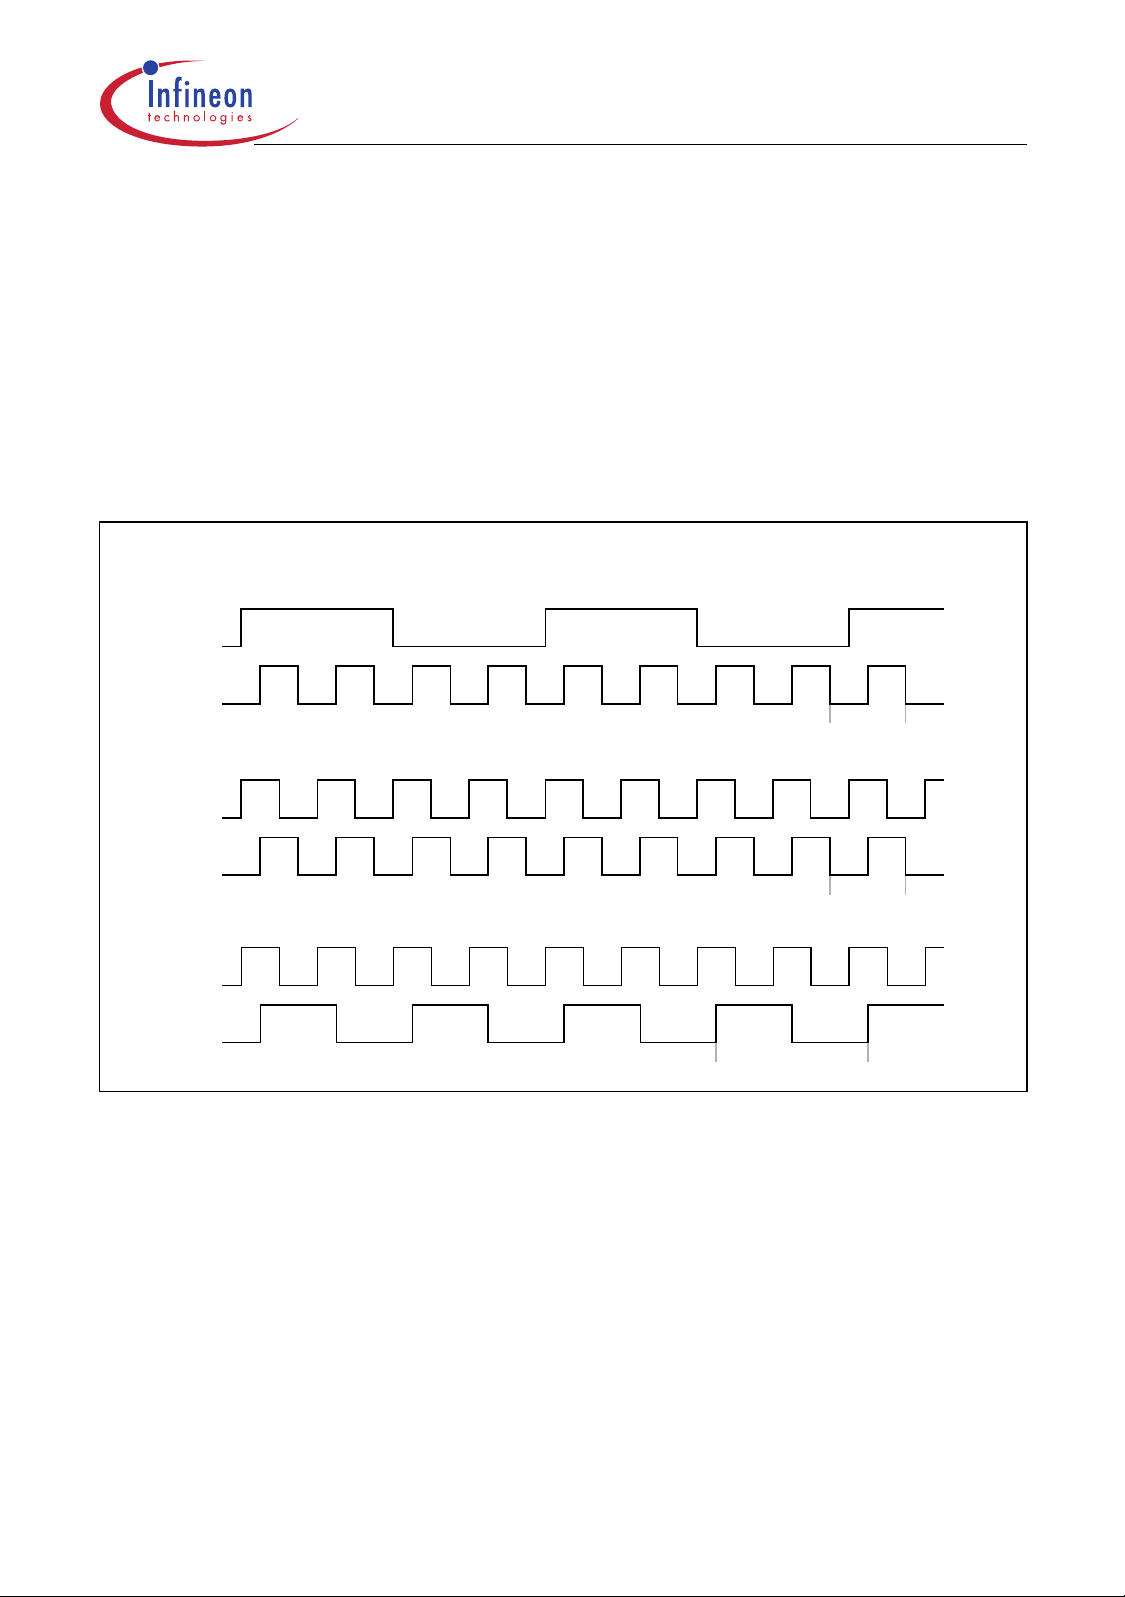
XC164
Derivatives
Timing Parameters
5 Timing Parameters
5.1 Definition of Internal Timing
The internal operation of the XC164 is controlled by the internal master clock fMC.
The master clock signal fMC can be generated from the oscillator clock signal f
different mechanisms. The duration of master clock periods (TCMs) and their variation
(and also the derived external timing) depend on the used mechanism to generate fMC.
This influence must be regarded when calculating the timings for the XC164.
Phase Locked Loop Operation (1:N)
f
OSC
f
MC
TCM
OSC
via
Direct Clock Drive (1:1)
f
OSC
f
MC
TCM
Prescaler Opera tio n (N:1)
f
OSC
f
MC
TCM
Figure 15 Generation Mechanisms for the Master Clock
Note: The example for PLL operation shown in Figure 15 refers to a PLL factor of 1:4,
the example for prescaler operation refers to a divider factor of 2:1.
The used mechanism to generate the master clock is selected by register PLLCON.
CPU and EBC are clocked with the C PU clock signa l f
same frequency as the master clock (f
two: f
= fMC / 2. This factor is selected by bit CPSYS in register SYSCON1.
CPU
= fMC) or can be the master clock divided by
CPU
. The CPU clock can have the
CPU
The specification of the external timing (AC C haracteristics) depends on the per iod of the
CPU clock, called “TCP”.
The other peripherals are supplied with the system clock signal f
frequency as the CPU clock signal f
Data Sheet 56 V2.1, 2003-06
CPU
.
which has the same
SYS
Page 61
XC164
Derivatives
Timing Parameters
Bypass Operation
When bypass operation is confi gured (PLLCTR L = 0xB) the master clock is derived from
the internal oscillator (input clock signal XTAL1) through the input- and outputprescalers:
f
= f
MC
If both divider factors are selected as ’1’ (PLLIDIV = PLLODIV = ’0’) the frequency of f
directly follows the frequency of f
duty cycle of the input clock f
/ ((PLLIDIV+1)×(PLLODIV+1)).
OSC
.
OSC
so the high and low time of fMC is defined by the
OSC
MC
The lowest master clock frequency is achieved by selecting the maximum values for both
divider factors:
f
MC
= f
/ ((3+1)×(14+1)) = f
OSC
OSC
/ 60.
Phase Locked Loop (PLL)
When PLL operation is configured (PLLCTRL = 11B) the on-chip phase locked loop is
enabled and provides the master clock. The PLL multiplies the input frequency by the
factor F (fMC = f
× F) which results from the input divider, the multiplication factor,
OSC
and the output divider (F = PLLMUL+1 / (PLLIDIV+1 × PLLODIV+1)). The PLL circuit
synchronizes the master clock to the input clock. This synchronization is done smoothly,
i.e. the master clock frequency does not change abruptly.
Due to this adaptation to the input clock the frequency of fMC is constantly adjusted so it
is locked to f
. The slight variation causes a jitter of fMC which also affects the duration
OSC
of individual TCMs.
The timing li sted in th e AC Characteristi cs re fers to TCPs. Because f
f
, the timing must be calculated using the minimum TCP possi ble under the respective
MC
is derived from
CPU
circumstances.
The actual minimum value for TCP depends on the jitter of the PLL. As the PLL is
constantly adjusting its output fr equency so it cor responds to the applied i nput freque ncy
(crystal or oscillator) the relative deviation for periods of m ore than one TCP is lower than
for one single TCP (see formula and Figure 16).
This is especially important for bus cycles using waitstates and e.g. for the operation of
timers, serial interfaces, etc. For all slower operations and longer periods (e.g. pulse train
generation or measurement , lower baudrates, etc.) the deviation caused by the PLL jitter
is negligible.
The value of the accumulated PLL jitter depends on the number of consecutive VCO
output cycles within the respective timeframe. The VCO output clock is divided by the
output prescaler (K = PLLODIV+1) to generate the master clock signal
f
. Therefore,
MC
the number of VCO cycles can be represented as K × N, where N is the number of
consecutive fMC cycles (TCM).
Data Sheet 57 V2.1, 2003-06
Page 62
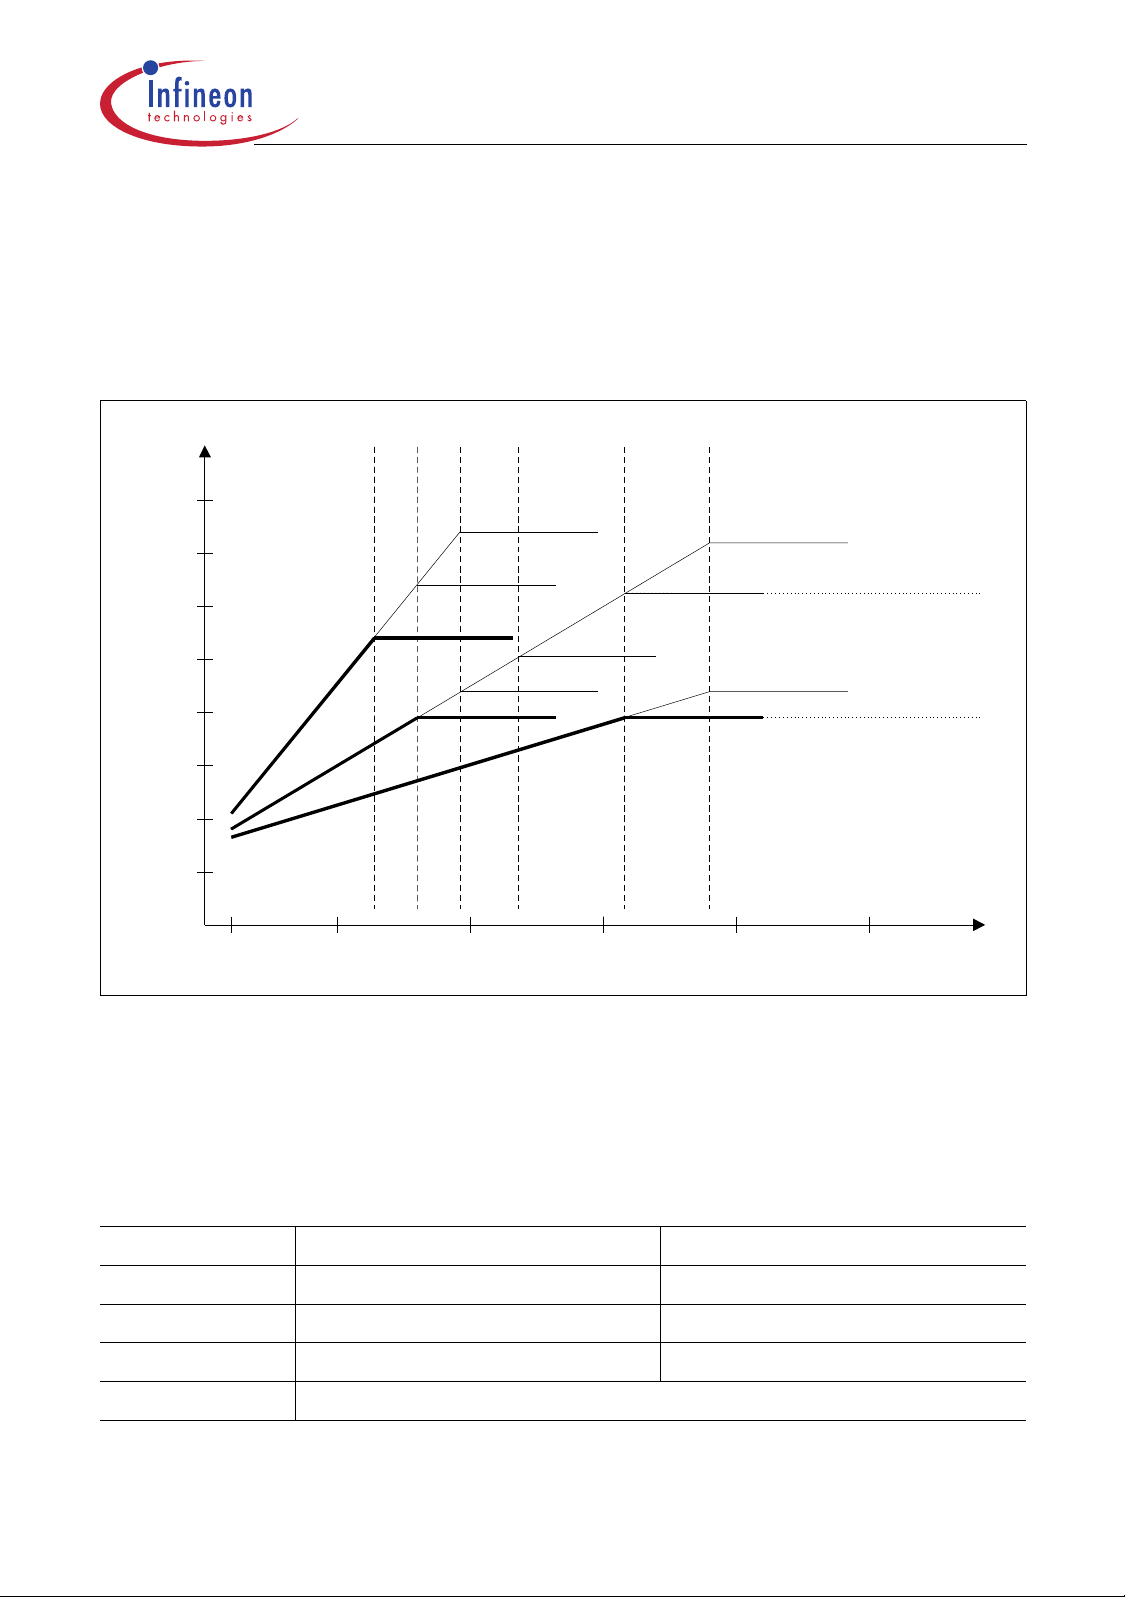
XC164
Derivatives
Timing Parameters
For a period of N × TCM the accumulated PLL jitter is defined by the deviation DN:
DN [ns] = ±(1.5 + 6.32 × N / fMC); fMC in [MHz], N = number of consecutive TCMs.
So, for a period of 3 TCMs @ 20 MHz and K = 12: D3 = ±(1.5 + 6.32 × 3 / 20) = 2.448 ns.
This formula is applicable for K × N < 95. For longer periods the K×N=95 value can be
used. This steady value can be approximated by: D
A cc . jitter
ns
±8
±7
±6
±5
±4
±3
±2
D
N
z
H
M
0
1
z
H
M
0
2
z
H
M
0
4
K=6K=12K=15 K=8K=10
[ns] = ±(1.5 + 600 / (K × fMC)).
Nmax
K=5
±1
0
1
510 20
15
25
mcb04413_xc .vsd
N
Figure 16 Approximated Accumulated PLL Jitter
Note: The bold lines indicate the minimum accumulated jitter which can be achieved by
selecting the maximum possible output prescaler factor K.
Different frequency bands can be selected for the V CO, so the operati on of the PLL can
be adjusted to a wide range of input and output frequencies:
Table 15 VCO Bands for PLL Operation
1)
PLLCON.PLLVB VCO Frequency Range Base Frequency Range
00 100 … 150 MHz 20 … 80 MHz
01 150 … 200 MHz 40 … 130 MHz
10 200 … 250 MHz 60 … 180 MHz
11 Reserved
1)
Values guarnteed by design characterisation.
Data Sheet 58 V2.1, 2003-06
Page 63
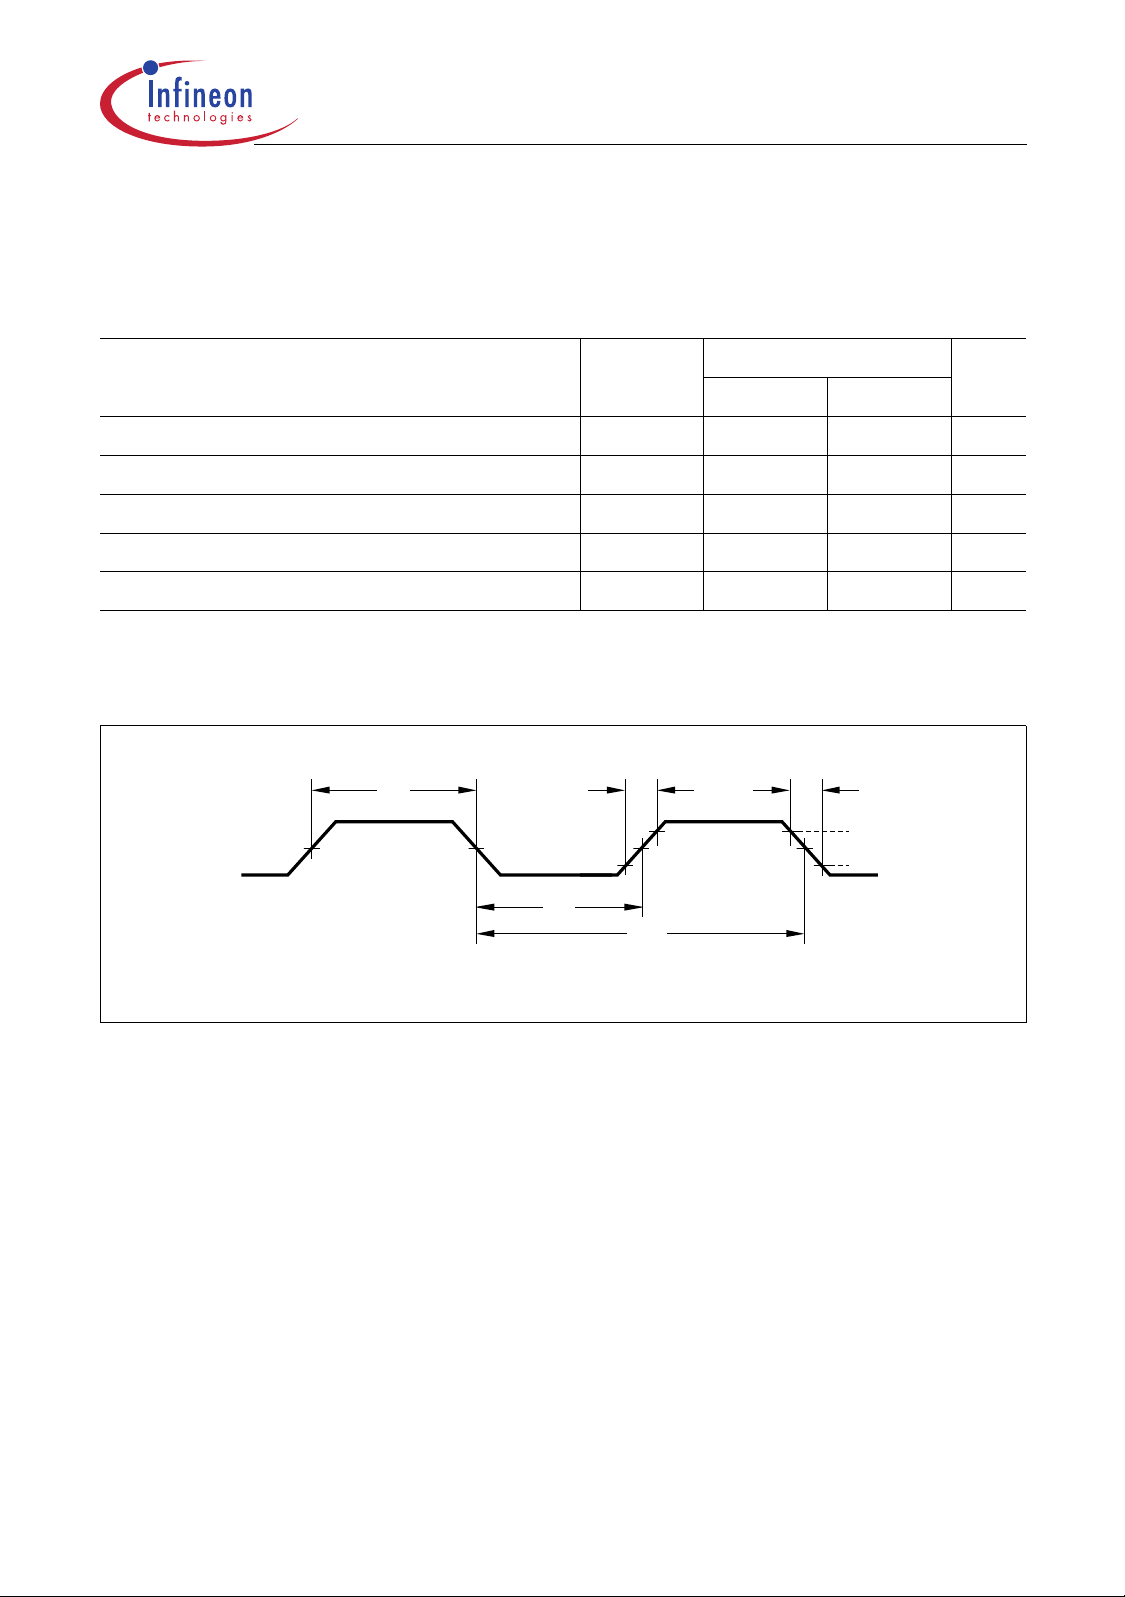
XC164
Derivatives
Timing Parameters
5.2 External Clock Drive XTAL1
Table 16 E xternal Clock Drive Characteristics
(Operating Conditions apply)
Parameter Symbol Limit Values Unit
min. max.
Oscillator period t
2)
2)
2)
2)
t
t
t
t
ILC
High time
Low time
Rise time
Fall time
1)
The maximum limit is only relevant for PLL operation to ensure the minimum input frequency for the PLL.
2)
The clock input signal must reach the defined levels V
SR 20 250
OSC
SR 6 – ns
1
SR 6 – ns
2
SR – 8 ns
3
SR – 8 ns
4
and V
IHC
.
1)
ns
0.5
t
1
V
DDI
t
2
t
t
3
OSC
t
4
MCT05138
V
IHC
V
ILC
Figure 17 External Clock Drive XTAL1
Note: If the on-chip oscillator is used together with a crystal or a ceramic resonator, the
oscillator frequency is limited to a range of 4 MHz to 16 MHz.
It is strongly recommended to measure the oscillation allowance (negative
resistance) in the final target system (layout) to determine the optimum
parameters for the oscillator operation. Please refer to the limits specified by the
crystal supplier.
When driven by an external clock signal it will accept the specified frequency
range. Operation at lower input frequencies is possible but is guaranteed by
design only (not 100% tested).
Data Sheet 59 V2.1, 2003-06
Page 64
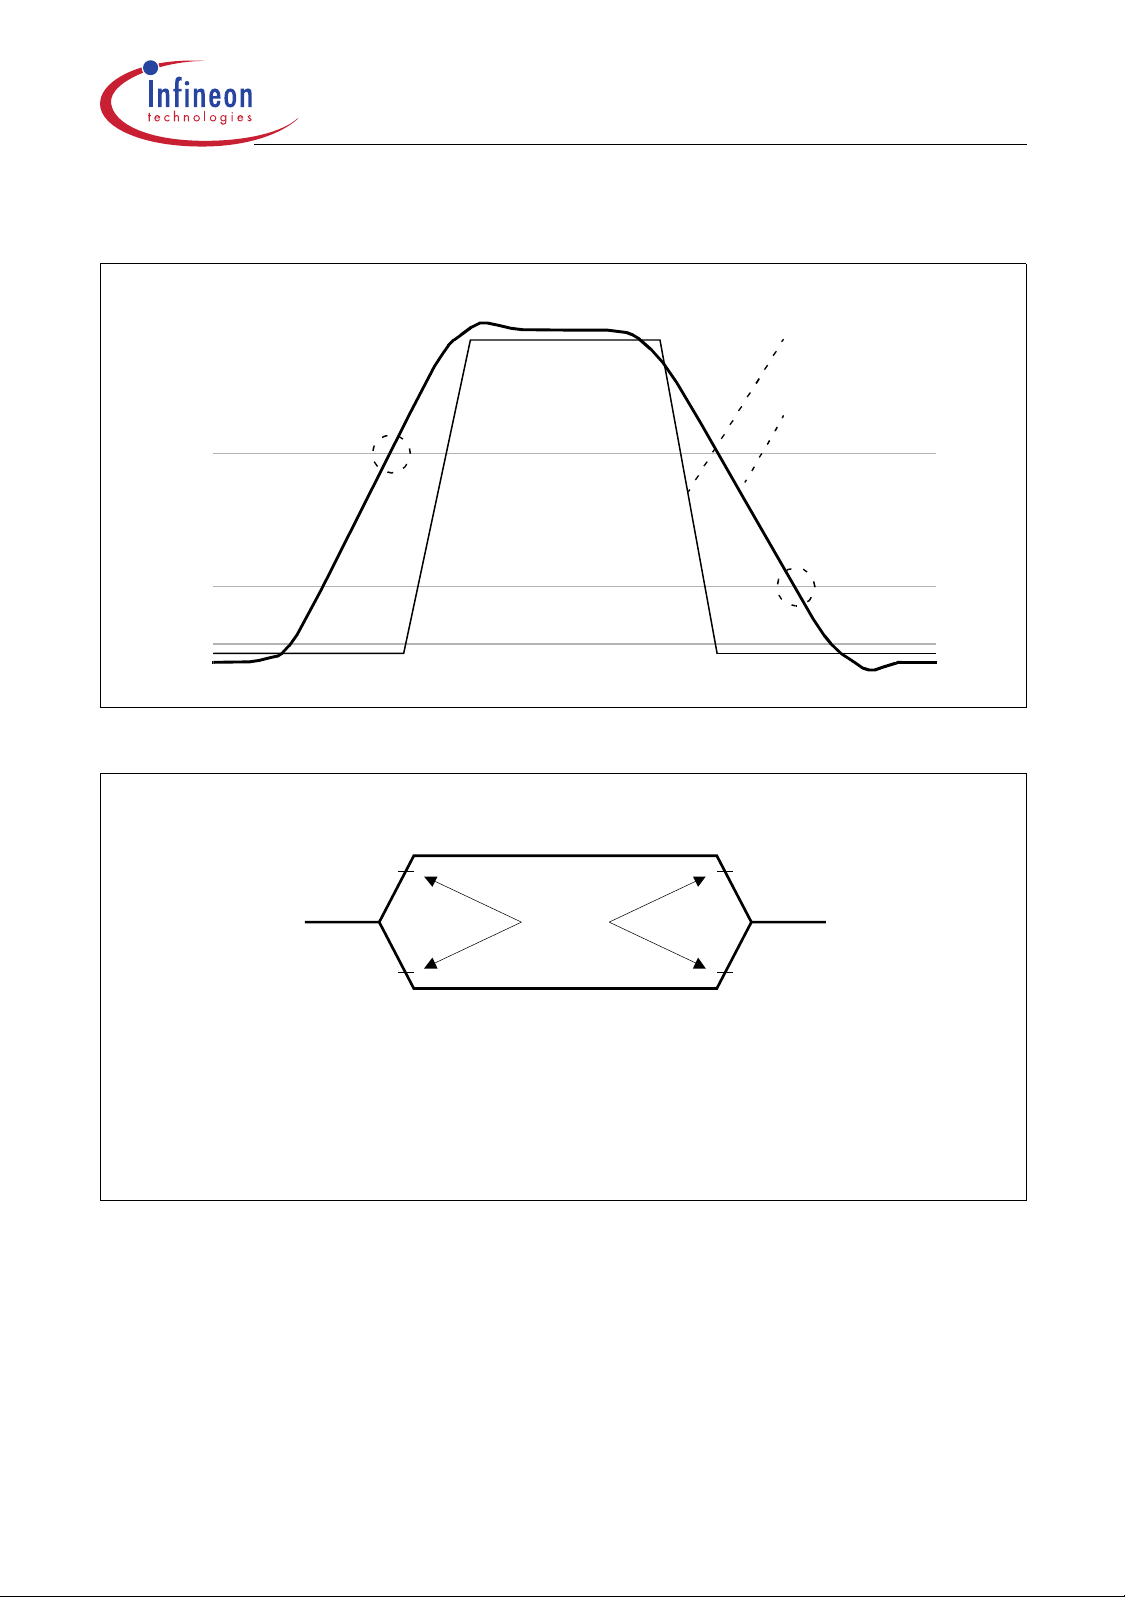
XC164
Derivatives
5.3 Testing Waveforms
2.0 V
0.8 V
0.45 V
Figure 18 Input Output Waveforms
Timing Parameters
Input signal
(driven by tester)
Output signal
(measured)
+ 0.1 V
V
Load
- 0.1 V
V
Load
For timing purposes a port pin is no longer floating when a 100 mV change from load voltage occurs,
but begins to float when a 100 mV change from the loaded
Figure 19 Float Waveforms
Timing
Reference
Points
- 0.1 V
V
OH
+ 0.1 V
V
OL
V
/
V
OH
level occurs (
OL
I
I
/ = 20 mA).
OH OL
MCA00763
Data Sheet 60 V2.1, 2003-06
Page 65
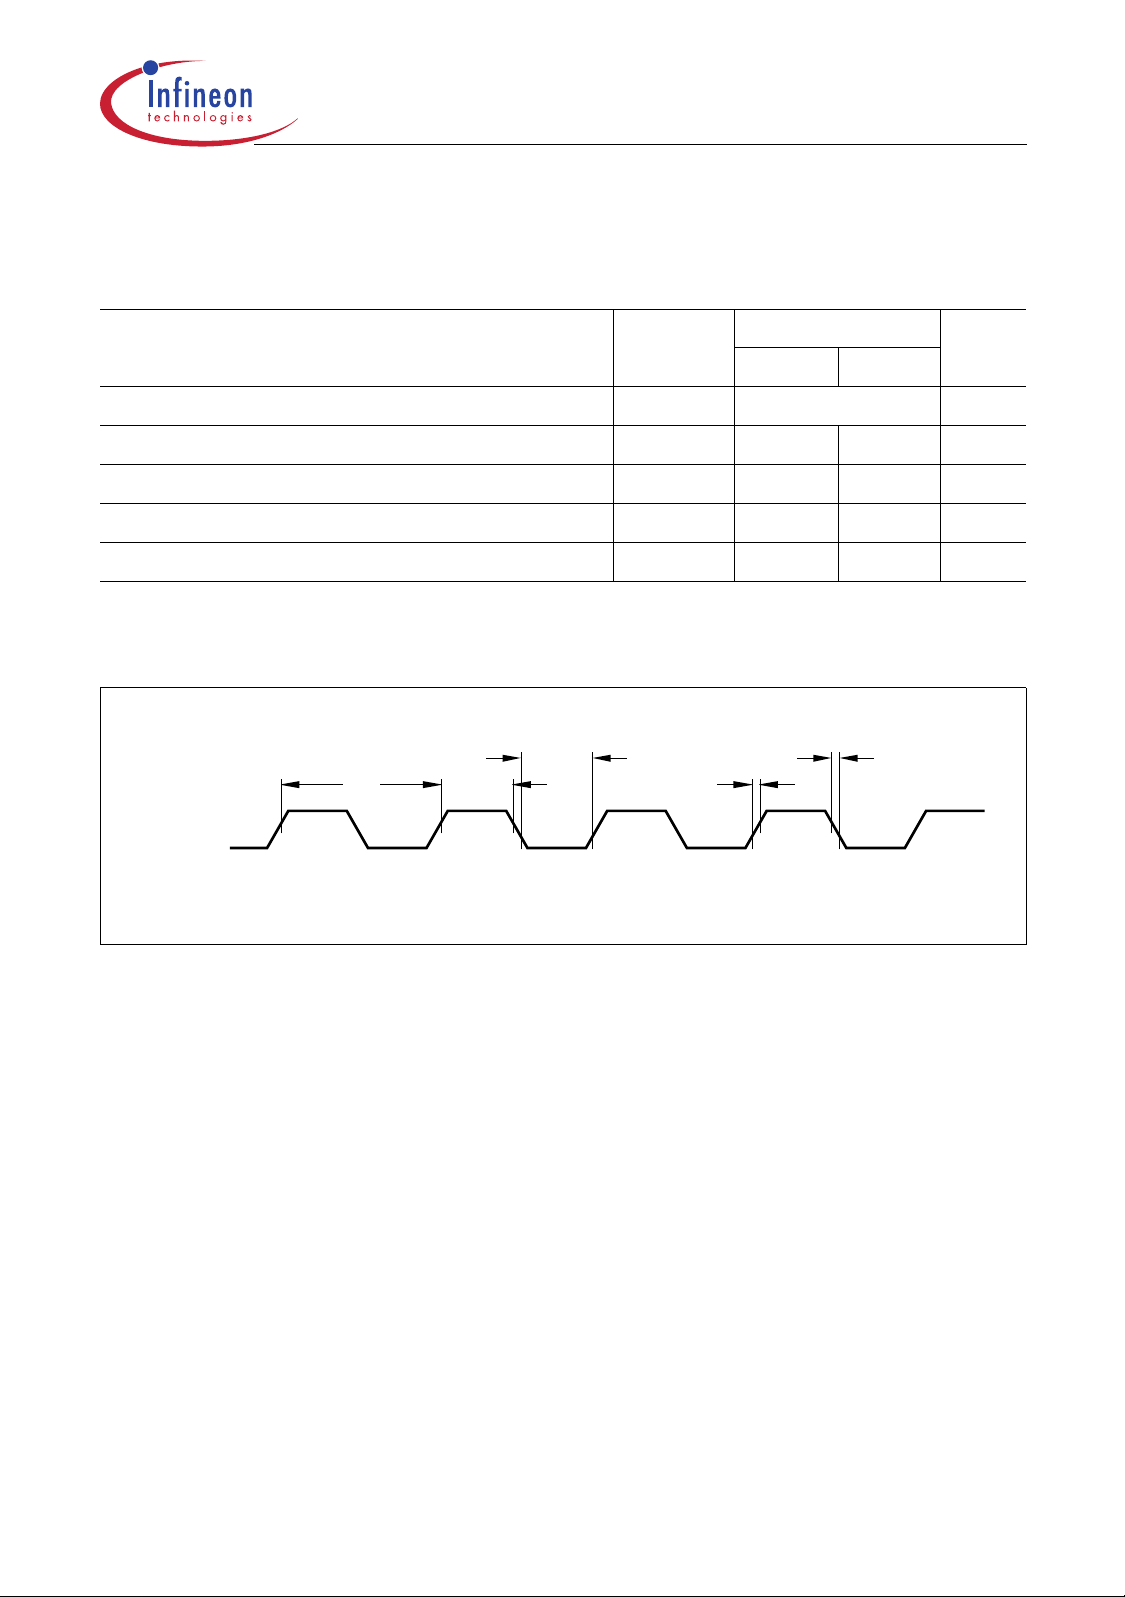
XC164
Derivatives
Timing Parameters
5.4 AC Characteristics
Table 17 CLKOUT Reference Signal
Parameter Symbol Limits Unit
min. max.
CLKOUT cycle time tc5 CC 40/30/25
CLKOUT high time tc6 CC 8 – ns
CLKOUT low time tc7 CC 6 – ns
CLKOUT rise time tc8 CC – 4 ns
CLKOUT fall time tc9 CC – 4 ns
1)
The CLKOUT cycle time is influenced by the PLL jitter (given values apply to f
For longer periods the relative deviation decreases (see PLL deviation formula).
= 25/33/40 MHz).
CPU
tc
tc
tc
7
5
tc
6
tc
8
1)
9
ns
CLKOUT
Figure 20 CLKOUT Signal Timing
MCT04415
Data Sheet 61 V2.1, 2003-06
Page 66
XC164
Derivatives
Timing Parameters
Variable Memory Cycles
External bus cycles of the XC164 are executed in five subsequent cycle phases (AB, C,
D, E, F). The duration of each cycle phase is programmable (via the TCONCSx
registers) to adapt the external bus cycles to the respective external module (memory,
peripheral, etc.).
This table provides a summary of the phases and the respective choices for their
duration.
Table 18 P rogrammable Bus Cycle Phases (see timing diagrams)
Bus Cycle Phase Parameter Valid Values Unit
Address setup phase, the standard duration of this
tp
AB
1 … 2 (5) TCP
phase (1 … 2 TCP) can be extended by 0 … 3 TCP if
the address window is changed
Command delay phase tp
Write Data setup / MUX Tristate phase tp
Access phase tp
Address / Write Data hold phase tp
C
D
E
F
0 … 3 TCP
0 … 1 TCP
1 … 32 TCP
0 … 3 TCP
Note: The bandwidth of a parameter (minimum and maximum value) covers the whole
operating range (temperature, voltage) as well as process variations. Within a
given device, however, this bandwidth is smaller than the specified range. This is
also due to interdependencies between certain parameters. Some of these
interdependencies are described in additional notes (see standard timing).
Data Sheet 62 V2.1, 2003-06
Page 67
XC164
Derivatives
Timing Parameters
Table 19 External Bus Cycle Timing (Operating Conditions apply)
Parameter Symbol L imits Unit
min. max.
Output valid delay for:
tc
CC 113ns
10
RD, WR(L/H)
Output valid delay for:
tc
CC -1 7 ns
11
A23…A16, BHE, ALE
Output valid delay for:
tc
CC 116ns
12
A15…A0 (on PORT1)
Output valid delay for:
tc
CC 316ns
13
A15…A0 (on PORT0)
Output valid delay for:
tc
CC 114ns
14
CS
Output valid delay for:
tc
CC 317ns
15
D15…D0 (write data, mux-mode)
Output valid delay for:
tc
CC 317ns
16
D15…D0 (write data, demux-mode)
Output hold time for:
tc
CC -3 3ns
20
RD, WR(L/H)
Output hold time for:
tc
CC 0 8ns
21
A23…A16, BHE, ALE
Output hold time for:
tc
CC 1 13 ns
23
A15…A0 (on PORT0)
tc
Output hold time for:
CC -3 3ns
24
CS
Output hold time for:
tc
CC 1 13 ns
25
D15…D0 (write data)
Input setup time for:
tc
SR 24 – ns
30
READY, D15…D0 (read data)
Input hold time
READY, D15…D0 (read data)
1)
Read data are l atched with the sam e (inter nal) c lock edge tha t tri ggers th e addres s chan ge and t he ri sing e dge
. Theref ore addres s chang es be fore the end of RD have no impact on (dem ultiple xed) read cycles . Read
of RD
data can be removed after the rising edge of RD
1)
.
tc
SR -5 – ns
31
Note: The shaded parameters have been verified by characterization.
They are not 100% tested.
Data Sheet 63 V2.1, 2003-06
Page 68
XC164
Derivatives
CLKOUT
A23-A16,
BHE, CSx
WR(L/H)
ALE
RD
tp
AB
tc
11
tc11|tc
14
tc
tp
21
Timing Parameters
C
tp
D
tp
E
tp
F
High Address
tc
10
tc
20
tc
13
AD15-AD0
Low Address Data In
(read)
tc
13
AD15-AD0
(write)
Figure 21 Multiplexed Bus Cycle
tc
tc
23
15
tc
tc
30
31
tc
25
Data OutLow Address
Data Sheet 64 V2.1, 2003-06
Page 69
XC164
Derivatives
CLKOUT
A23-A0,
BHE, CSx
WR(L/H)
ALE
RD
tp
AB
tc
11
tc11|tc
14
tc
tp
21
Timing Parameters
C
tp
D
tp
E
tp
F
Address
tc
10
tc
20
D15-D0
(read)
D15-D0
(write)
Figure 22 Demultiplexed Bus Cycle
tc
16
tc
30
Data In
Data Out
tc
31
tc
25
Data Sheet 65 V2.1, 2003-06
Page 70
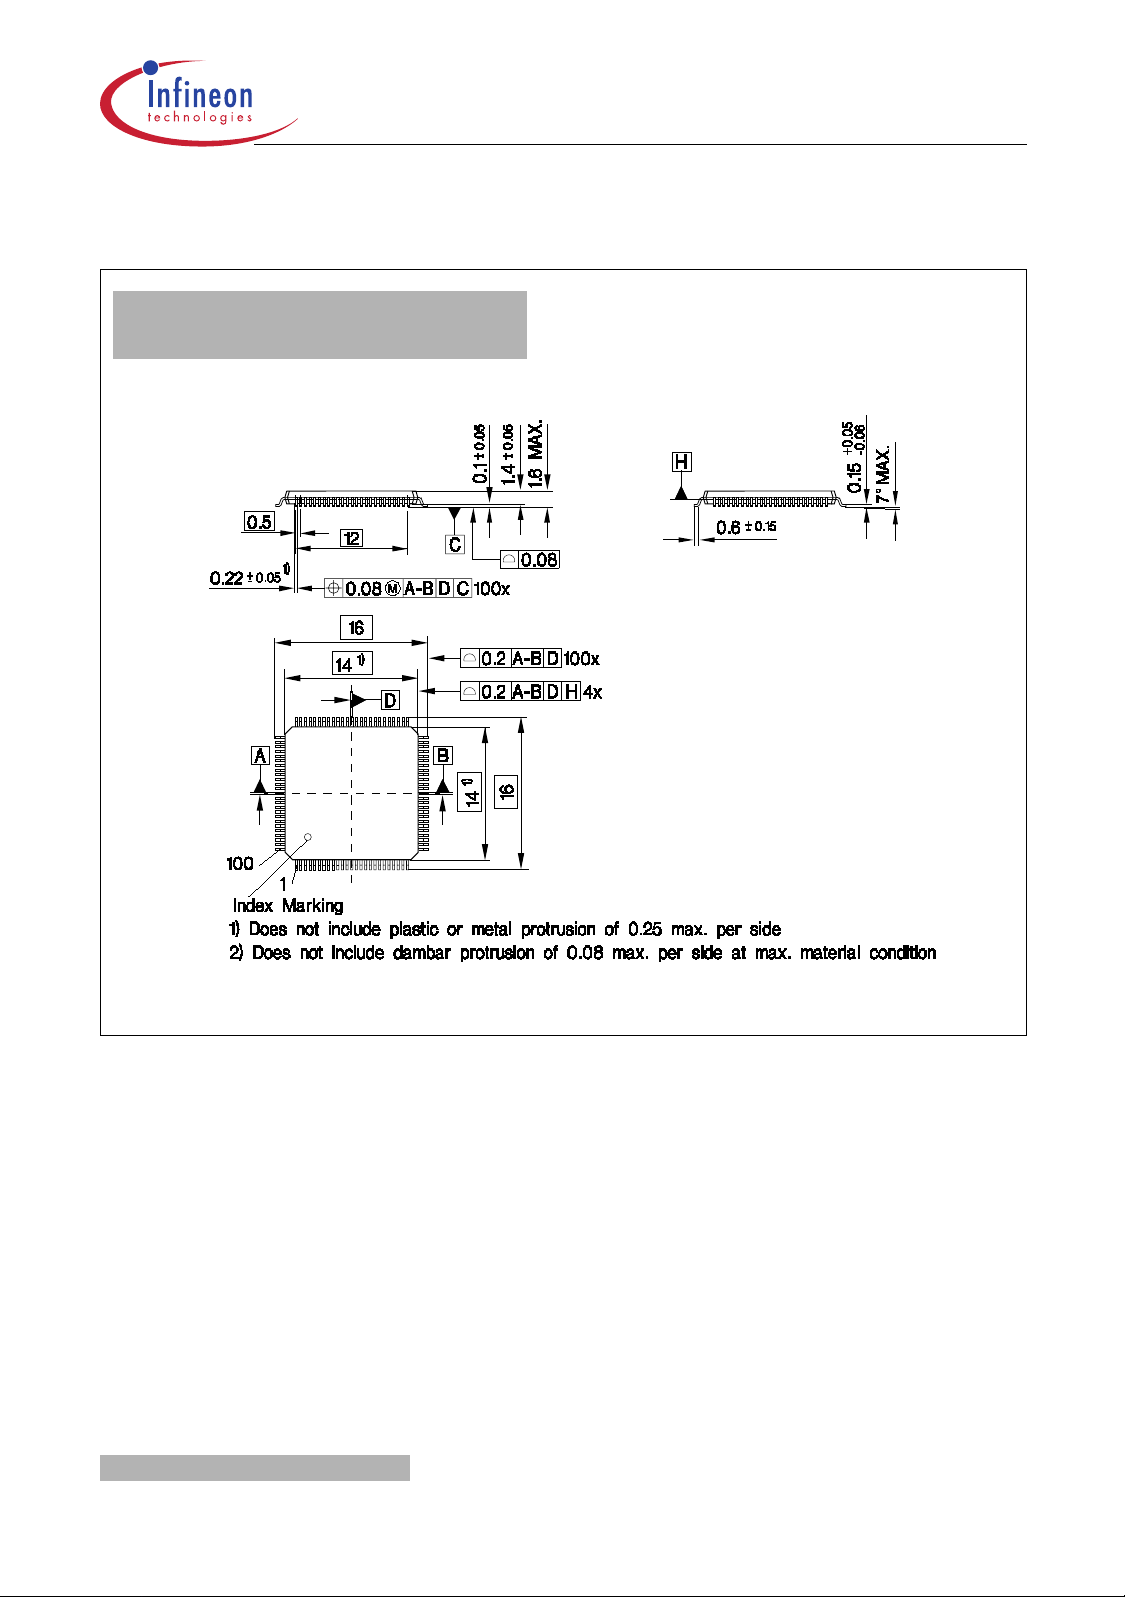
XC164
m
Derivatives
6 Packaging
P-TQFP-100-16
(Plastic Metric Quad Flat Package)
Packaging
Figure 23 Package Outlines P-TQFP-100-16
Sorts of Packing
Package outlines for tubes, trays etc. are contained in our
Data Book “Package Information”.
SMD = Surface Mounted Device
Data Sheet 66 V2.1, 2003-06
Dimensions in m
Page 71
http://www.infineon.com
Published by Infineon Technologies AG
 Loading...