

Page 1
INTEGRATED CIRCUITS
DATA SH EET
TDA4855
Autosync Deflection Controller
(ASDC)
Preliminary specification
File under Integrated Circuits, IC02
1996 Jul 18
Page 2
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
FEATURES
Concept features
• Full Horizontal (H) plus Vertical (V) autosync capability
• Completely DC controllable for analog and digital
concepts
• Excellent geometry control functions (e.g. automatic
correction of East-West (EW) parabola during
adjustment of vertical size and vertical shift)
• Flexible Switched Mode Power Supply (SMPS) function
block for feedback and feed forward converters
• Horizontal focus parabola with amplitude control
• X-ray protection
• Start-up and switch-off sequence for safe operation of
all power components
• Very good vertical linearity
• Internal supply voltage stabilization
• SDIP32 package.
Synchronization inputs
• Can handle all sync signals (Horizontal, Vertical,
Composite and Sync-on-video)
• Combined output for video clamping, vertical blanking
and protection blanking.
Horizontal section
• Extremely low jitter
• Frequency locked loop for smooth catching of line
frequency
• Simple frequency preset of f
min
and f
by external
max
resistors
• DC controllable wide range linear picture position
• Soft start for horizontal driver.
Vertical section
• Vertical amplitude independent of frequency
• Automatic correction of picture height for VGA350 and
VGA400 modes
• DC controllable picture height, picture position and
S-correction
• Differential current outputs for DC coupling to vertical
booster.
EW section
• Output for DC adjustable EW parabola with smoothed
top
• DC controllable picture width and trapezium correction
• Optional tracking of EW parabola with line frequency
• Prepared for additional DC controls of vertical linearity,
EW-corner, EW pin balance, EW parallelogram, vertical
focus by extended application.
GENERAL DESCRIPTION
The TDA4855 is a high performance and efficient solution
for autosync monitors. The concept is fully DC controllable
and can be used in applications with a microcontroller and
stand-alone in rock bottom solutions.
The TDA4855 provides synchronization processing, H + V
synchronization with full autosync capability, and very
short settling times after mode changes. External power
components are given a great deal of protection. The IC
generates the drive waveforms for DC-coupled vertical
boosters such as TDA486X and TDA8351.
The TDA4855 provides extended functions e.g. as a
flexible SMPS block and an extensive set of geometry
control facilities, providing excellent picture quality.
Together with the Philips TDA488X video processor family
a very advanced system solution is offered.
1996 Jul 18 2
Page 3
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
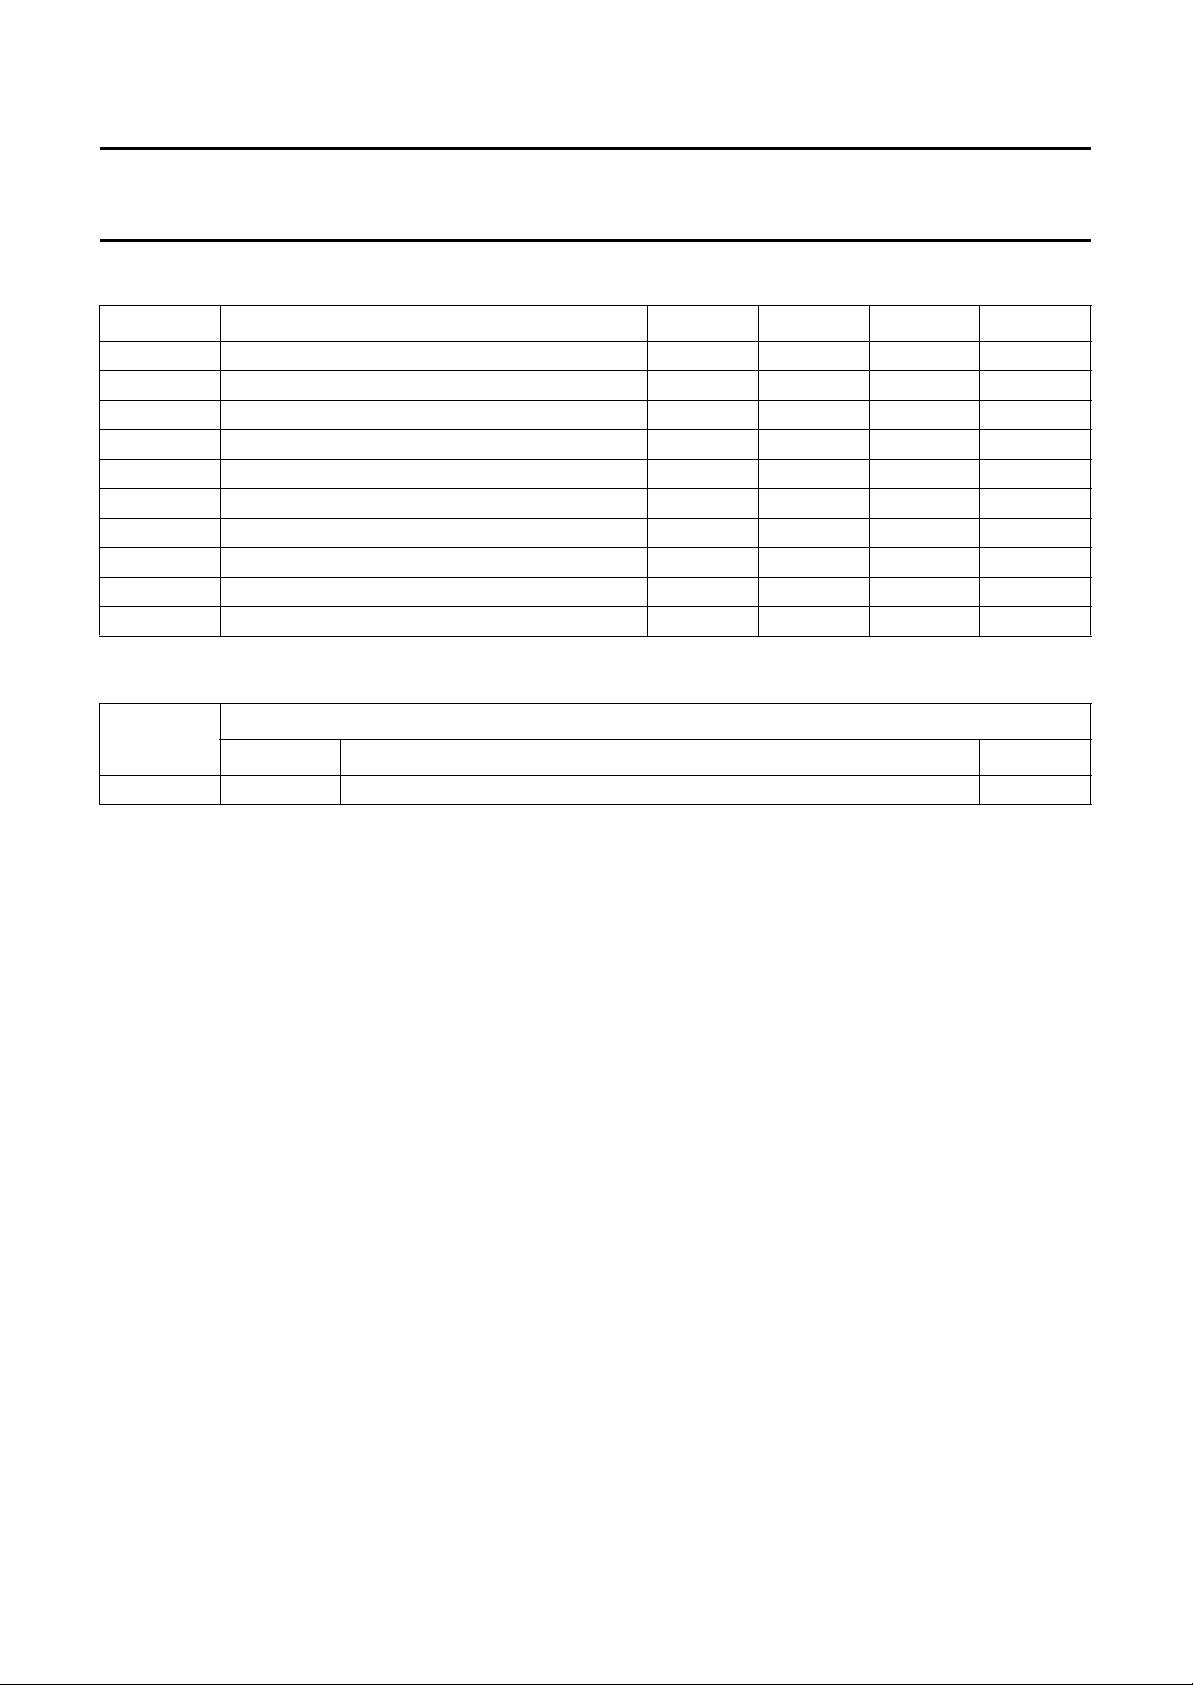
QUICK REFERENCE DATA
SYMBOL PARAMETER MIN. TYP. MAX. UNIT
V
CC
I
CC
∆HPOS horizontal shift adjustment range −±10.5 − %
∆VAMP vertical size adjustment range 60 − 100 %
∆VPOS vertical shift adjustment range −±11.5 − %
∆VSCOR vertical S-correction adjustment range 2 − 46 %
∆V
EWPAR
∆V
EWWID
∆V
EWTRP
T
amb
ORDERING INFORMATION
supply voltage 9.2 − 16 V
supply current − 49 − mA
EW parabola adjustment range 0.15 − 3.0 V
horizontal size adjustment range 0.2 − 4.0 V
trapezium correction adjustment range −±0.5 − V
operating ambient temperature 0 − 70 °C
TYPE
NUMBER
NAME DESCRIPTION VERSION
PACKAGE
TDA4855 SDIP32 plastic shrink dual in-line package; 32 leads (400 mil) SOT232-1
1996 Jul 18 3
Page 4
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
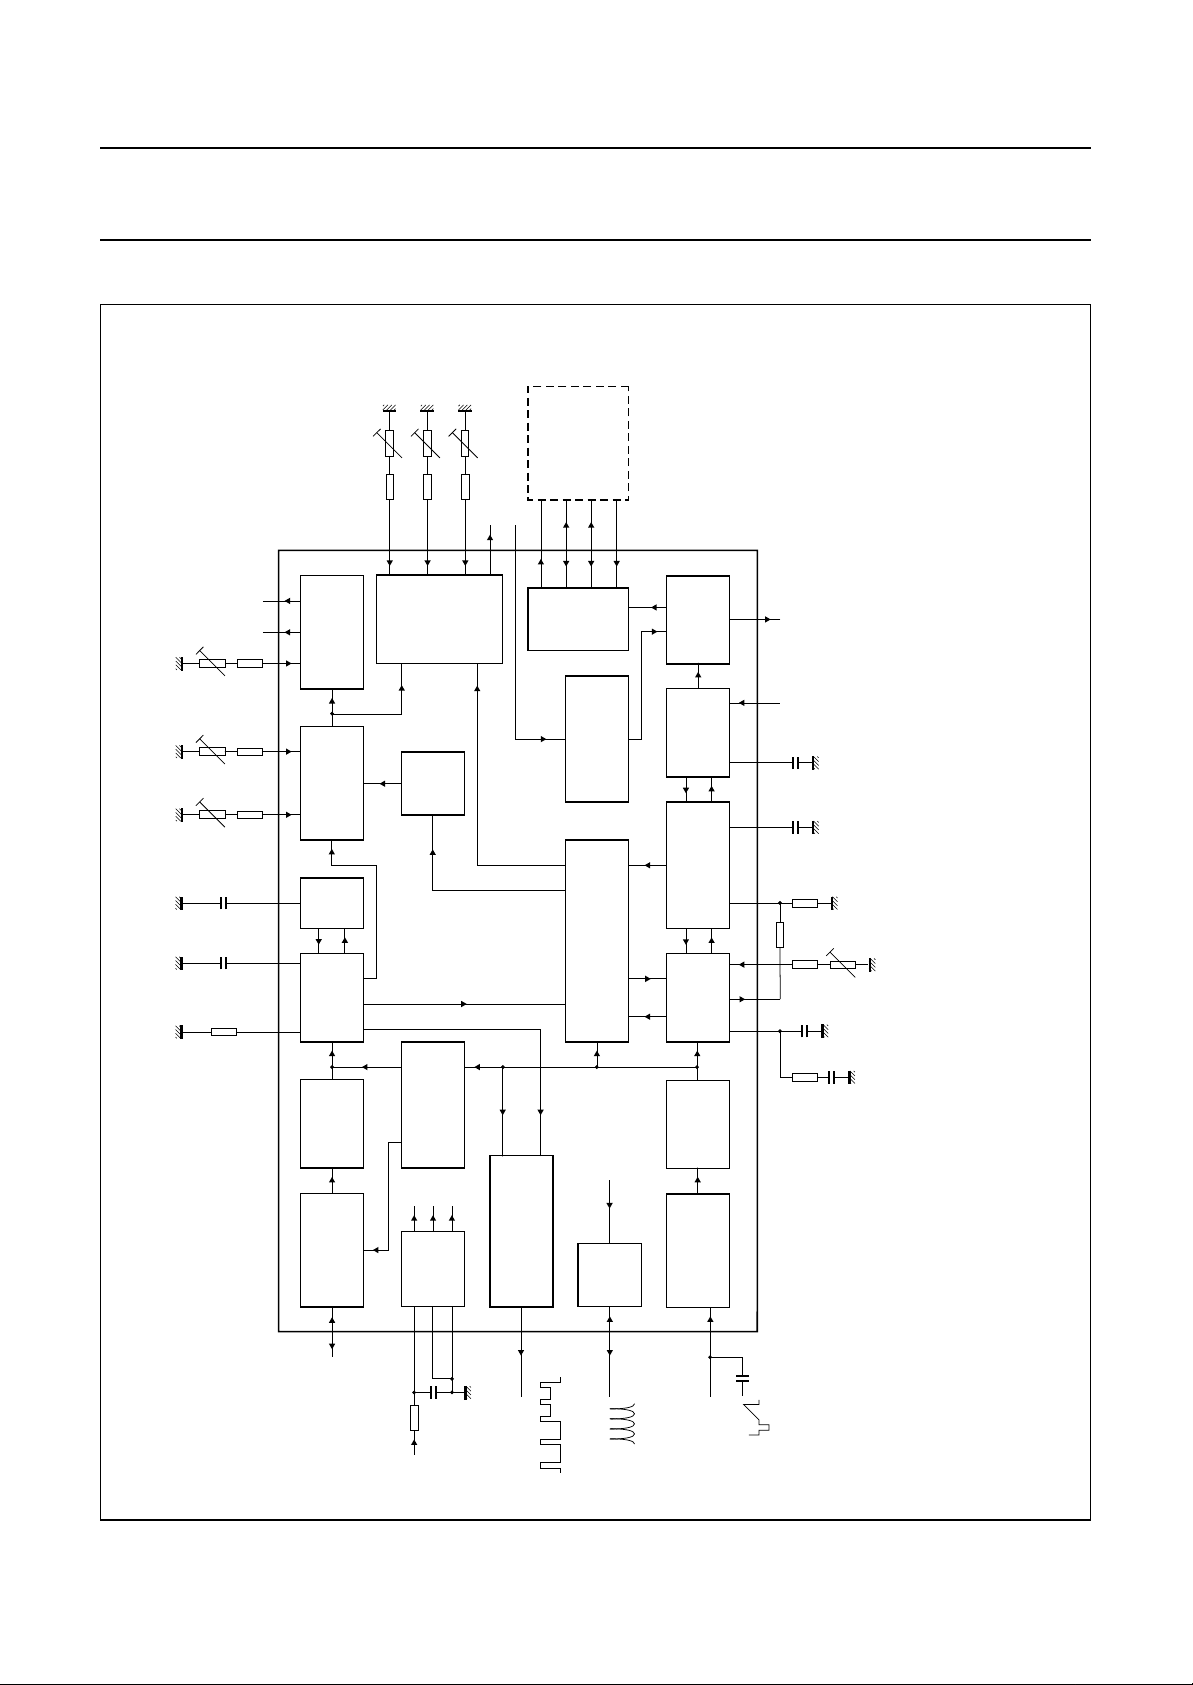
BLOCK DIAGRAM
EW
parabola
horizontal
size
EW
39 kΩ
EWPAR
21
220 kΩ
39 kΩ
EWWID
32
220 kΩ
39 kΩ
EWTRP
20
trapeziun
220 kΩ
EWDRV
11
2
XRAY
BDRV
6
(3)
B+ CONTROL
BSENS
4
APPLICATION
BOP
BIN
3
5
MBG550
VPOS VAMP VSCOR
220 kΩ
220 kΩ
220 kΩ
100
100
22
nF
nF
kΩ
VREF
R
VAGC
C
5%
VCAP
C
1%
VOUT1 VOUT2
39 kΩ
39 kΩ
39 kΩ
VCAP VAGC
VREF
23 24 22 17 18 19 13 12
VERTICAL
S-CORRECTION
OUTPUT STAGE
VERTICAL SIZE
VERTICAL POSITION
AGC
VERTICAL
OSCILLATOR
POLARITY
CORRECTION
EW
PARABOLA
VGA
PRESETS
TDA4855
INTEGRATOR
VERTICAL SYNC
B+
CONTROL
X-RAY
PROTECTION
FREQUENCY DETECTOR
COINCIDENCE DETECTOR
HFLB
STAGE
OUTPUT
HORIZONTAL
OSCILLATOR
HORIZONTAL
PLL1 PLL2
POLARITY
CORRECTION
HDRV
HFLB
12 nF
HPLL2
2%
10 nF
HCAP
(1)
HREF
R
HREF
(1)
HBUF
R
30 28 29 31 1 7
220
HPOS
kΩ
39
HPLL1 HBUF
kΩ
nF
1.5
(2)
27
26
handbook, full pagewidth
Fig.1 Block diagram and application circuit.
47 nF
27 kΩ
SYNC
INPUT
VERTICAL
14
VSYNC
(TTL level)
AND
SUPPLY
9825
PGND
9.2 to 16 V
CC
V
REFERENCE
SGND
VERTICAL BLANKING
VIDEO CLAMPING PULSE
16
CLBL
blanking
clamping
1996 Jul 18 4
10
FOCUS
H-focus
parabola
FOCUS
COMPOSITE
SYNC INPUT
HORIZONTAL/
15
HSYNC
(TTL level)
(video)
range.
H
(1) See calculation of f
(2) See note 3 of Chapter “Characteristics”.
(3) See Figs 12 and 13.
Page 5
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
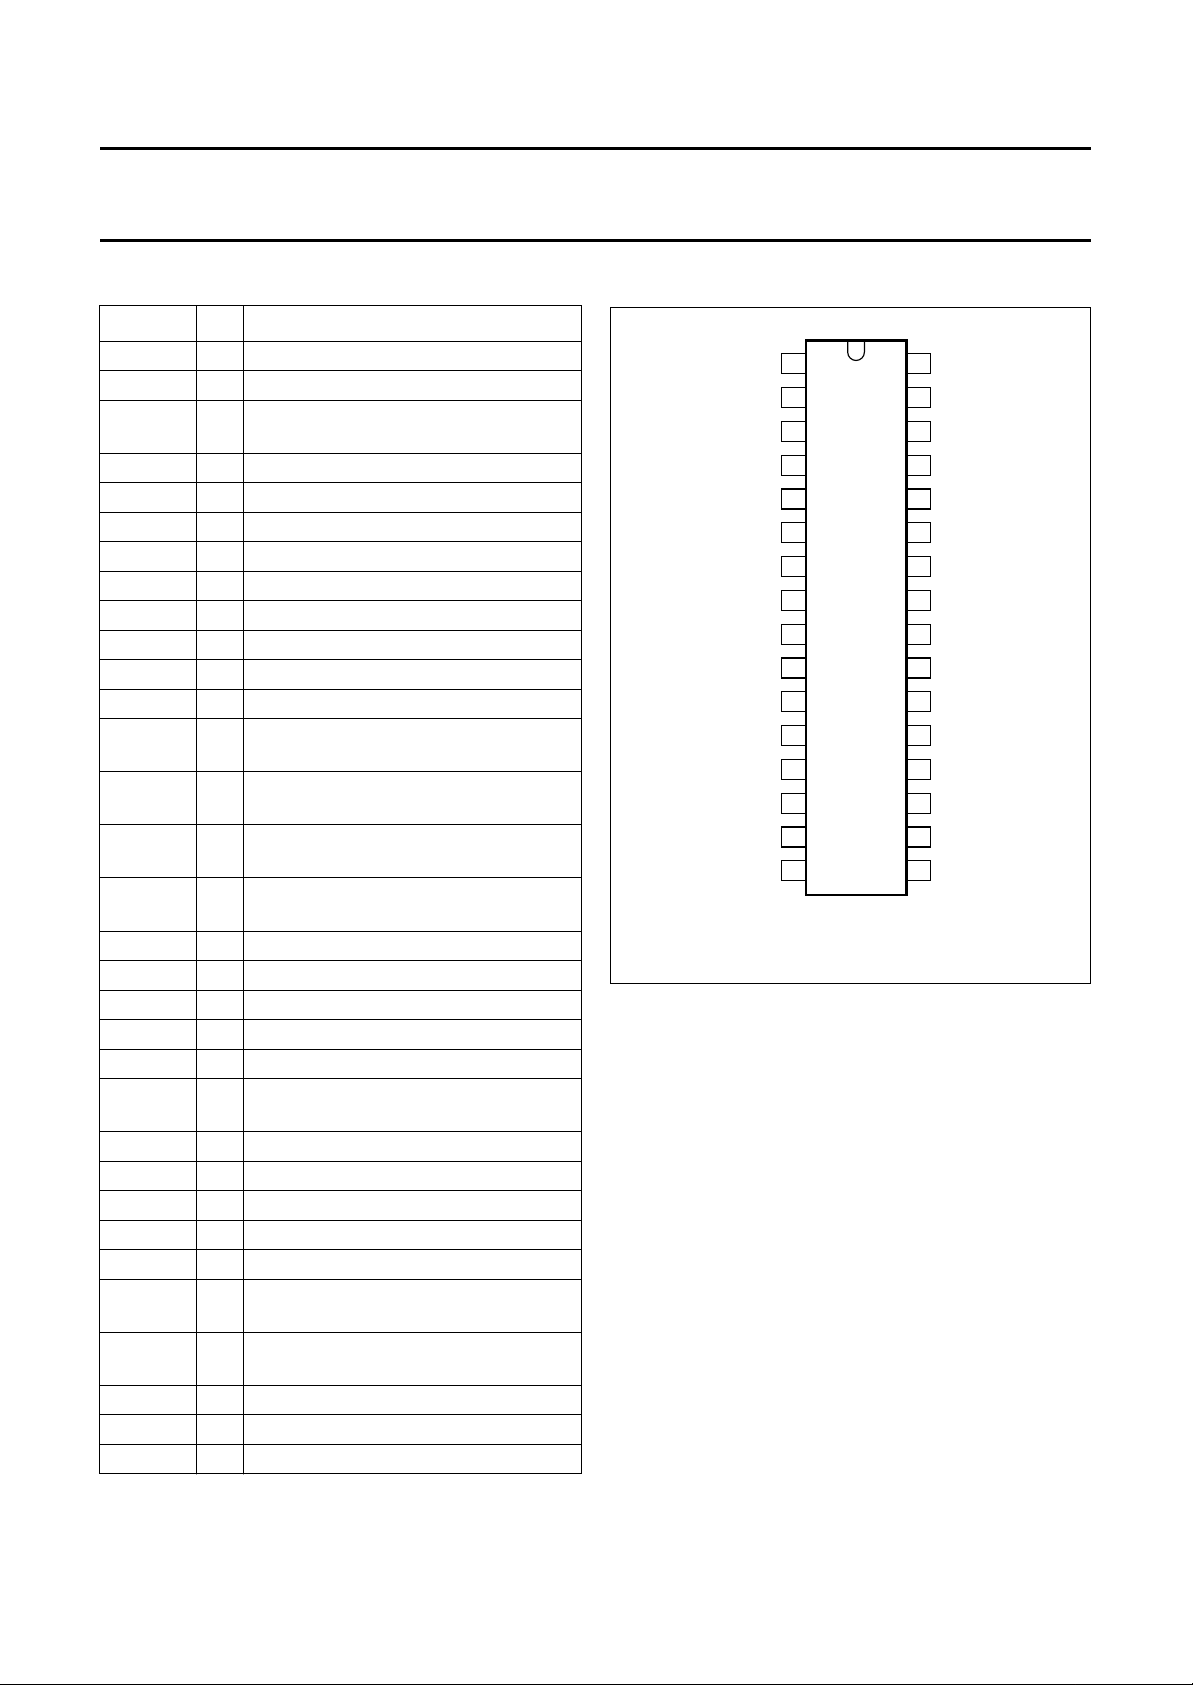
PINNING
SYMBOL PIN DESCRIPTION
HFLB 1 horizontal flyback input
XRAY 2 X-ray protection input
BOP 3 B+ control OTA output;
comparator input
BSENS 4 B+ control comparator input/output
BIN 5 B+ control OTA input
BDRV 6 B+ control driver output
HDRV 7 horizontal driver output
PGND 8 power ground
V
CC
9 supply voltage
FOCUS 10 horizontal focus parabola input/output
EWDRV 11 EW parabola output
VOUT2 12 vertical output 2 (ascending sawtooth)
VOUT1 13 vertical output 1 (descending
sawtooth)
VSYNC 14 vertical synchronization input/output
(TTL level)
HSYNC 15 horizontal/composite synchronization
input (TTL level or sync-on-video)
CLBL 16 video clamping pulse/vertical blanking
and protection output
VPOS 17 vertical shift input
VAMP 18 vertical size input
VSCOR 19 vertical S-correction input
EWTRP 20 EW trapezium correction input
EWPAR 21 EW parabola amplitude input
VAGC 22 external capacitor for vertical
amplitude control
VREF 23 external resistor for vertical oscillator
VCAP 24 external capacitor for vertical oscillator
SGND 25 signal ground
HPLL1 26 external filter for PLL1
HBUF 27 buffered f/v voltage output
HREF 28 reference current for horizontal
oscillator
HCAP 29 external capacitor for horizontal
oscillator
HPOS 30 horizontal shift input
HPLL2 31 external filter for PLL2/soft start
EWWID 32 horizontal size input
handbook, halfpage
1
HFLB
2
XRAY
3
BOP
BIN
BDRV
HDRV
PGND
V
CC
CLBL
4
5
6
7
8
9
10
11
12
13
14
15
16
TDA4855
MBG549
BSENS
FOCUS
EWDRV
VOUT2
VOUT1
VSYNC
HSYNC
Fig.2 Pin configuration.
32
31
30
29
28
27
26
25
24
23
22
21
20
19
18
17
EWWID
HPLL2
HPOS
HCAP
HREF
HBUF
HPLL1
SGND
VCAP
VREF
VAGC
EWPAR
EWTRP
VSCOR
VAMP
VPOS
1996 Jul 18 5
Page 6
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
FUNCTIONAL DESCRIPTION
Horizontal sync separator and polarity correction
HSYNC (pin 15) is the input for horizontal synchronization
signals, which can be DC-coupled TTL signals (horizontal
or composite sync) and AC-coupled negative-going video
sync signals. Video syncs are clamped to 1.28 V and
sliced at 1.4 V. This results in a fixed absolute slicing level
of 120 mV related to sync top.
For DC-coupled TTL signals the input clamping current is
limited. The slicing level for TTL signals is 1.4 V.
The separated sync signal (either video or TTL) is
integrated on an internal capacitor to detect and normalize
the sync polarity.
Normalized horizontal sync pulses are used as input
signals for the vertical sync integrator, the PLL1 phase
detector and the frequency-locked loop.
Vertical sync integrator
Normalized composite sync signals from HSYNC are
integrated on an internal capacitor in order to extract
vertical sync pulses. The integration time is dependent on
the horizontal oscillator reference current at HREF
(pin 28). The integrator output directly triggers the vertical
oscillator. This signal is available at VSYNC (normally
vertical sync input; pin 14), which is used as an output in
this mode.
Vertical sync slicer and polarity correction
Vertical sync signals (TTL) applied to VSYNC (pin 14) are
sliced at 1.4 V. The output signal of the sync slicer is
integrated on an internal capacitor to detect and normalize
the sync polarity.
If a composite sync signal is detected at HSYNC, VSYNC
is used as output for the integrated vertical sync (e.g. for
power saving applications).
Video clamping/vertical blanking generator
The lower level of the sandcastle pulse is the vertical
blanking pulse, which is derived directly from the internal
oscillator waveform. It is started by the vertical sync and
stopped with the start of the vertical scan. This results in
optimum vertical blanking.
Blanking will be activated continuously, if one of the
following conditions is true:
No horizontal flyback pulses at HFLB (pin 1)
X-ray protection is activated
Soft start of horizontal drive (voltage at HPLL2 (pin 31)
is low)
Supply voltage at V
PLL1 is unlocked while frequency-locked loop is in
search mode.
Blanking will not be activated if the horizontal sync
frequency is below the valid range or there are no sync
pulses available.
VGA mode detector
The polarities of horizontal and vertical sync are internally
detected in order to provide an automatic adjustment of
vertical size for VGA350 and VGA400 modes.
These automatic VGA presets are activated only if the
current ratio I
(see Chapter “Characteristics”). Thus it is possible to
disable this function for a part of the frequency range or
even completely.
Table 1 VGA modes
MODE
VGA350 + −
VGA400 − +
VGA480 −−
HBUF/IHREF
−++
(pin 9) is low (see Fig.14)
CC
exceeds a fixed value
HORIZONTAL/VERTICAL SYNC
POLARITY
The video clamping/vertical blanking signal at CLBL
(pin 16) is a two-level sandcastle pulse which is especially
suitable for video ICs such as the TDA488X family, but
also for direct applications in video output stages.
The upper level is the video clamping pulse, which is
triggered by the trailing edge of the horizontal sync pulse.
The width of the video clamping pulse is determined by an
internal monoflop.
1996 Jul 18 6
Page 7

Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
Frequency-locked loop
The frequency-locked loop can lock the horizontal
oscillator over a wide frequency range. This is achieved by
a combined search and PLL operation. The frequency
range is preset by two external resistors and the
recommended maximum ratio is
f
min
---------- f
max
1
=
------- -
3.5
Larger ranges are possible by extended applications.
Without a horizontal sync signal the oscillator will be
free-running at f
. Any change of sync conditions is
min
detected by the internal coincidence detector. A deviation
of more than 4% between horizontal sync and oscillator
frequency switches the horizontal section into search
mode. This means that PLL1 control currents are switched
off immediately. Then the internal frequency detector
starts tuning the oscillator. Very small DC currents at
HPLL1 (pin 26) are used to perform this tuning with a well
defined change rate. When coincidence between
horizontal sync and oscillator frequency is detected, the
search mode is replaced by a normal PLL operation.
This operation ensures a smooth tuning and avoids fast
changes of horizontal frequency during catching.
In this concept it is not allowed to load HPLL1.
The frequency dependent voltage at this pin is fed
internally to HBUF (pin 27) via a sample-and-hold and
buffer stage. The sample-and-hold stage removes all
disturbances caused by horizontal sync or composite
vertical sync from the buffered voltage. An external
resistor from HBUF to HREF defines the frequency range.
See also hints for locking procedure in note 3 of
Chapter “Characteristics”.
PLL1 phase detector
The phase detector is a standard type using switched
current sources. It compares the middle of horizontal sync
with a fixed point on the oscillator sawtooth voltage.
The PLL1 loop filter is connected to HPLL1 (pin 26).
The reference current at HREF also defines the integration
time constant of the vertical sync integration.
Calculation of line frequency range
First the oscillator frequencies f
min
and f
have to be
max
calculated. This is achieved by adding the spread of the
relevant components to the highest and lowest sync
frequencies f
the difference of the currents in R
highest oscillator frequency R
S(min)
and f
. The oscillator is driven by
S(max)
and R
HREF
does not contribute to
HBUF
HBUF
. At the
the spread. The spread will increase towards lower
frequencies due to the contribution of R
f
dependent on the ratio
n
S
S max()
=
------------------f
Smin()
HBUF
. It is also
The following example is a 31.45 to 64 kHz application:
n
S
f
S max()
------------------f
Smin()
64 kHz
---------------------------
31.45 kHz
2.04== =
Table 2 Calculation of total spread
spread of: for f
max
for f
min
IC 3% 3%
C
R
R
HCAP
HREF
HREF
, R
HBUF
2% 2%
1% −
− 1% × (2.3 × nS− 1)
Total 6% 8.69%
Thus the typical frequency range of the oscillator in this
example is:
f
maxfSmax()
f
f
min
Smin()
----------------- -
1.087
The resistors R
1.06× 67.84 kHz==
28.93 kHz==
HREF
and R
can be calculated with the
HBUF
following formulae:
Horizontal oscillator
The horizontal oscillator is of the relaxation type and
requires a capacitor of 10 nF at HCAP (pin 29).
For optimum jitter performance the value of 10 nF must not
be changed.
The maximum oscillator frequency is determined by a
resistor from HREF to ground. A resistor from HREF to
HBUF defines the frequency range.
1996 Jul 18 7
R
HREF
R
HBUF
Where:
74 kHz k××Ω
-------------------------------------f
max
R
HREF
-------------------------------------------- -
f
max
n
---------- f
min
kHz[]
1.19× n×
n1–
2.35==
1.091 kΩ==
2.26 kΩ==
Page 8
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
The spread of f
f
Smax()
ratio .
------------------f
Smin()
increases with the frequency
min
For higher ratios this spread can be reduced by using
resistors with less tolerances.
PLL2 phase detector
The PLL2 phase detector is similar to the PLL1 detector
and compares the line flyback pulse at HFLB (pin 1) with
the oscillator sawtooth voltage. The PLL2 detector thus
compensates for the delay in the external horizontal
deflection circuit by adjusting the phase of the HDRV
(pin 7) output pulse.
The phase between horizontal flyback and horizontal sync
can be controlled at HPOS (pin 30).
If HPLL2 is pulled to ground, horizontal output pulses,
vertical output currents and B+ control driver pulses are
inhibited. This means, HDRV (pin 7), BDRV (pin 6)
VOUT1 (pin 13) and VOUT2 (pin 12) are floating in this
state. PLL2 and the frequency-locked loop are disabled,
and CLBL (pin 16) provides a continuous blanking signal.
This option can be used for soft start, protection and
power-down modes. When the HPLL2 voltage is released
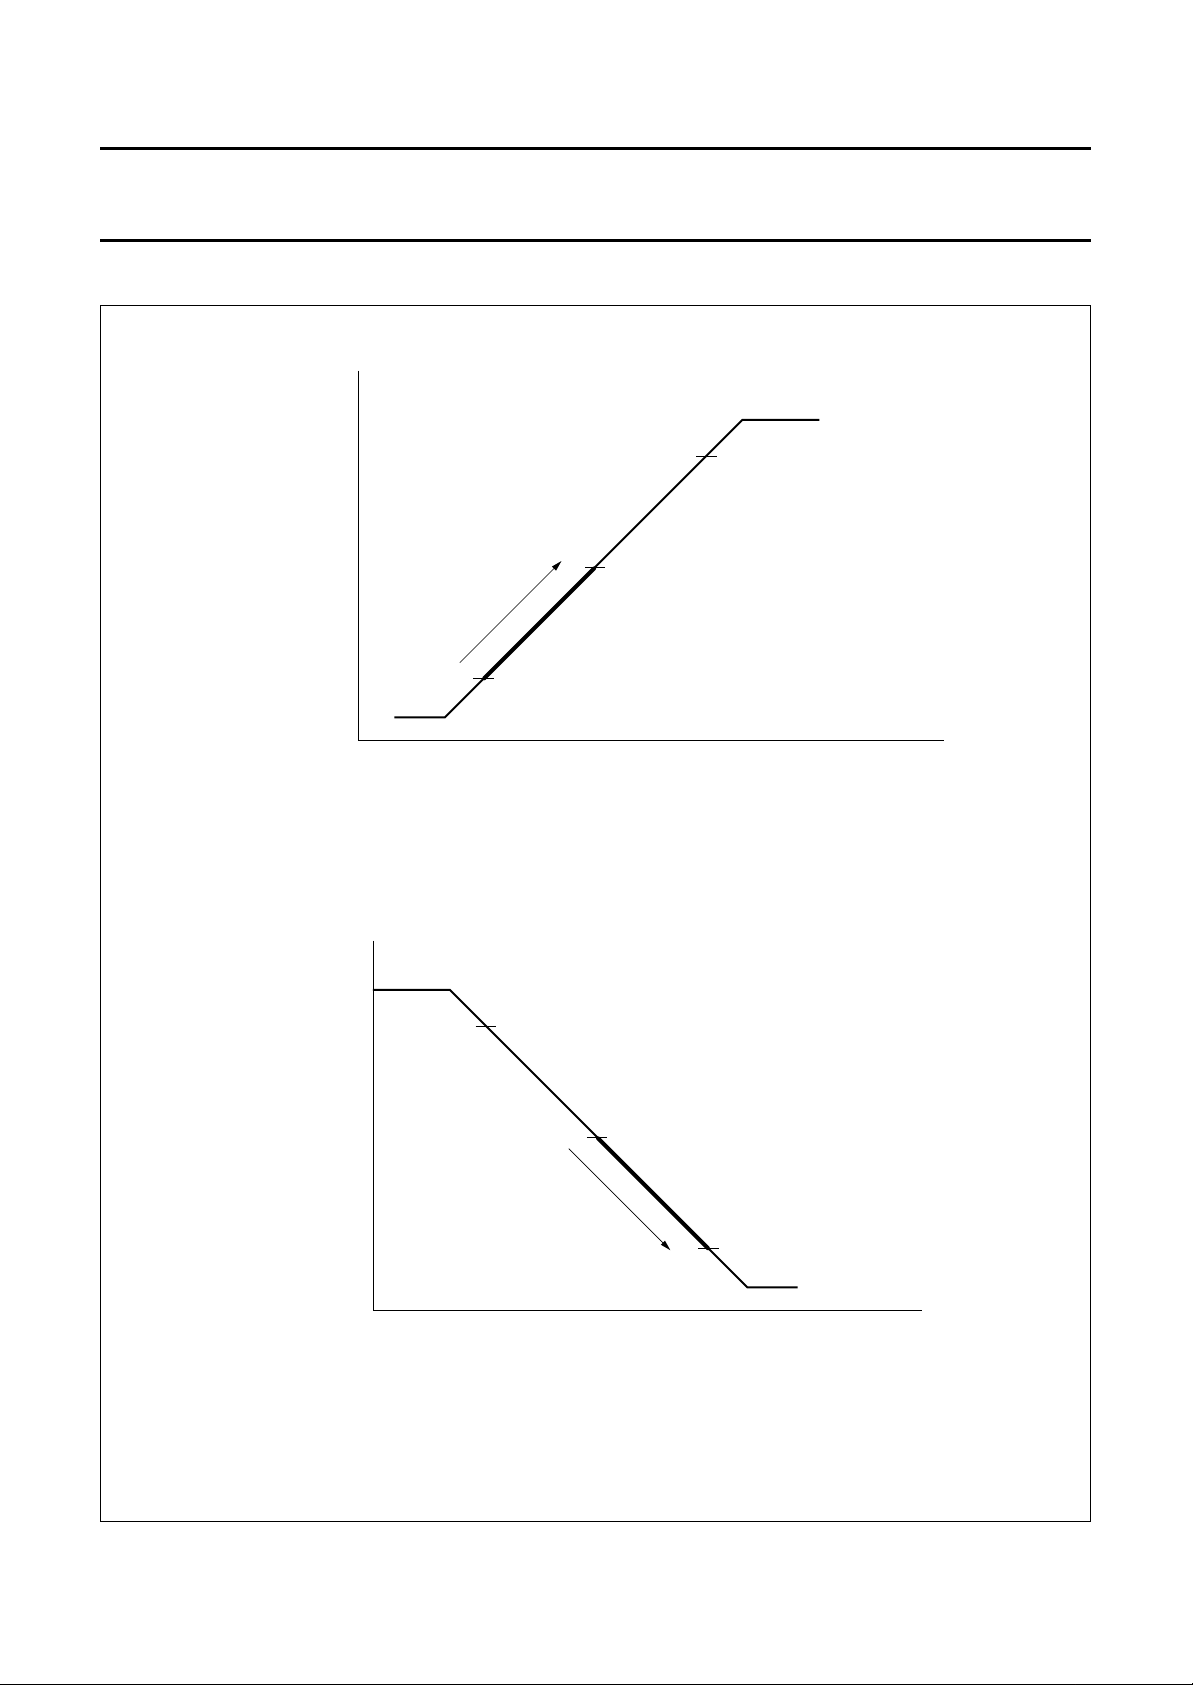
again, an automatic soft start sequence will be performed
(see Fig.15).
The soft start timing is determined by the filter capacitor at
HPLL2 (pin 31), which is charged with an constant current
during soft start. In the beginning the horizontal driver
stage generates very small output pulses. The width of
these pulses increases with the voltage at HPLL2 until the
final duty factor is reached. At this point BDRV (pin 6),
VOUT1 (pin 13) and VOUT2 (pin 12) are re-enabled.
The voltage at HPLL2 continues to rise until PLL2 enters
its normal operating range. The internal charge current is
now disabled. Finally PLL2 and the frequency-locked loop
are enabled, and the continuous blanking at CLBL is
removed.
Horizontal phase adjustment
HPOS (pin 30) provides a linear adjustment of the relative
phase between the horizontal sync and oscillator
sawtooth. Once adjusted, the relative phase remains
constant over the whole frequency range.
therefore the phase between horizontal sync and
horizontal drive pulse is only determined by PLL2.
Output stage for line drive pulses
An open collector output stage allows direct drive of an
inverting driver transistor because of a low saturation
voltage of 0.3 V at 20 mA. To protect the line deflection
transistor, the output stage is disabled (floating) for low
supply voltage at V
(see Fig.14).
CC
The duty factor of line drive pulses is slightly dependent on
the actual line frequency. This ensures optimum drive
conditions over the whole frequency range.
X-ray protection
The x-ray protection input XRAY (pin 2) provides a voltage
detector with a precise threshold. If the input voltage at
XRAY exceeds this threshold for a certain time, an internal
latch switches the IC into protection mode. In this mode
several pins are forced into defined states:
Horizontal output stage (HDRV) is floating
B+ control driver stage (BDRV) is floating
Vertical output stages (VOUT1 and VOUT2) are floating
CLBL provides a continuous blanking signal
The capacitor connected to HPLL2 (pin 31) is
discharged.
To reset the latch and return to normal operation, V
CC
has
to be temporarily switched off.
Vertical oscillator and amplitude control
This stage is designed for fast stabilization of vertical
amplitude after changes in sync frequency conditions.
The free-running frequency f
resistor R
C
connected to pin 24. The value of R
VCAP
connected to pin 23 and the capacitor
VREF
is determined by the
osc(V)
VREF
is not only
optimized for noise and linearity performance in the whole
vertical and EW section, but also influences several
internal references. Therefore the value of R
be changed. Capacitor C
should be used to select the
VCAP
VREF
must not
free-running frequency of the vertical oscillator in
accordance with the following formula:
f
osc V()
=
-----------------------------------------------------------
10.8 R
1
× C
VREF
×
VCAP
Application hint: HPOS is a current input, which provides
an internal reference voltage while I
is in the specified
HPOS
adjustment current range. By grounding HPOS the
symmetrical control range is forced to its centre value,
1996 Jul 18 8
Page 9
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
To achieve a stabilized amplitude the free-running
frequency f
, without adjustment, should be at least
osc(V)
10% lower than the minimum trigger frequency.
The contributions shown in Table 3 can be assumed.
Table 3 Calculation of f
osc(V)
total spread
Contributing elements:
Minimum frequency offset between f
osc(V)
±10%
and lowest trigger frequency
Spread of IC ±3%
Spread of R
Spread of C
VREF
VCAP
±1%
±5%
Total 19%
Result for 50 to 110 Hz application:
f
osc V()
50 Hz
---------------
1.19
42 Hz==
Application hint: VAGC (pin 22) has a high input
impedance during scan, thus the pin must not be loaded
externally. Otherwise non-linearities in the vertical output
currents may occur due to the changing charge current
during scan.
Application hint: The full vertical sync range of 1 : 2.5 can
be made usable by incorporating an adjustment of the
free-running frequency. Also the complete sync range can
be shifted to higher frequencies (e.g. 70 to 160 Hz) by
reducing the value of C
VCAP
.
Adjustment of vertical size, vertical shift and S-correction
VPOS (pin 17) is the input for the DC adjustable vertical
picture shift. This pin provides a phase shift at the
sawtooth output VOUT1 and VOUT2 (pins 13 and 12) and
the EW drive output EWDRV (pin 11) in such a way, that
the whole picture moves vertically while maintaining the
correct geometry.
The amplitude of the differential output currents at VOUT1
and VOUT2 can be adjusted via input VAMP (pin 18).
This can be a combination of a DC adjustment and a
dynamic waveform modulation.
VSCOR (pin 19) is used to adjust the amount of vertical
S-correction in the output signal.
The adjustments for vertical size and vertical shift also
affect the waveforms of the EW parabola and the vertical
S-correction. The result of this interaction is that no
readjustment of these parameters is necessary after an
adjustment of vertical picture size or position.
Application hint: VPOS is a current input, which provides
an internal reference voltage while I
is in the specified
VPOS
adjustment current range. By grounding VPOS (pin 17) the
symmetrical control range is forced to its centre value.
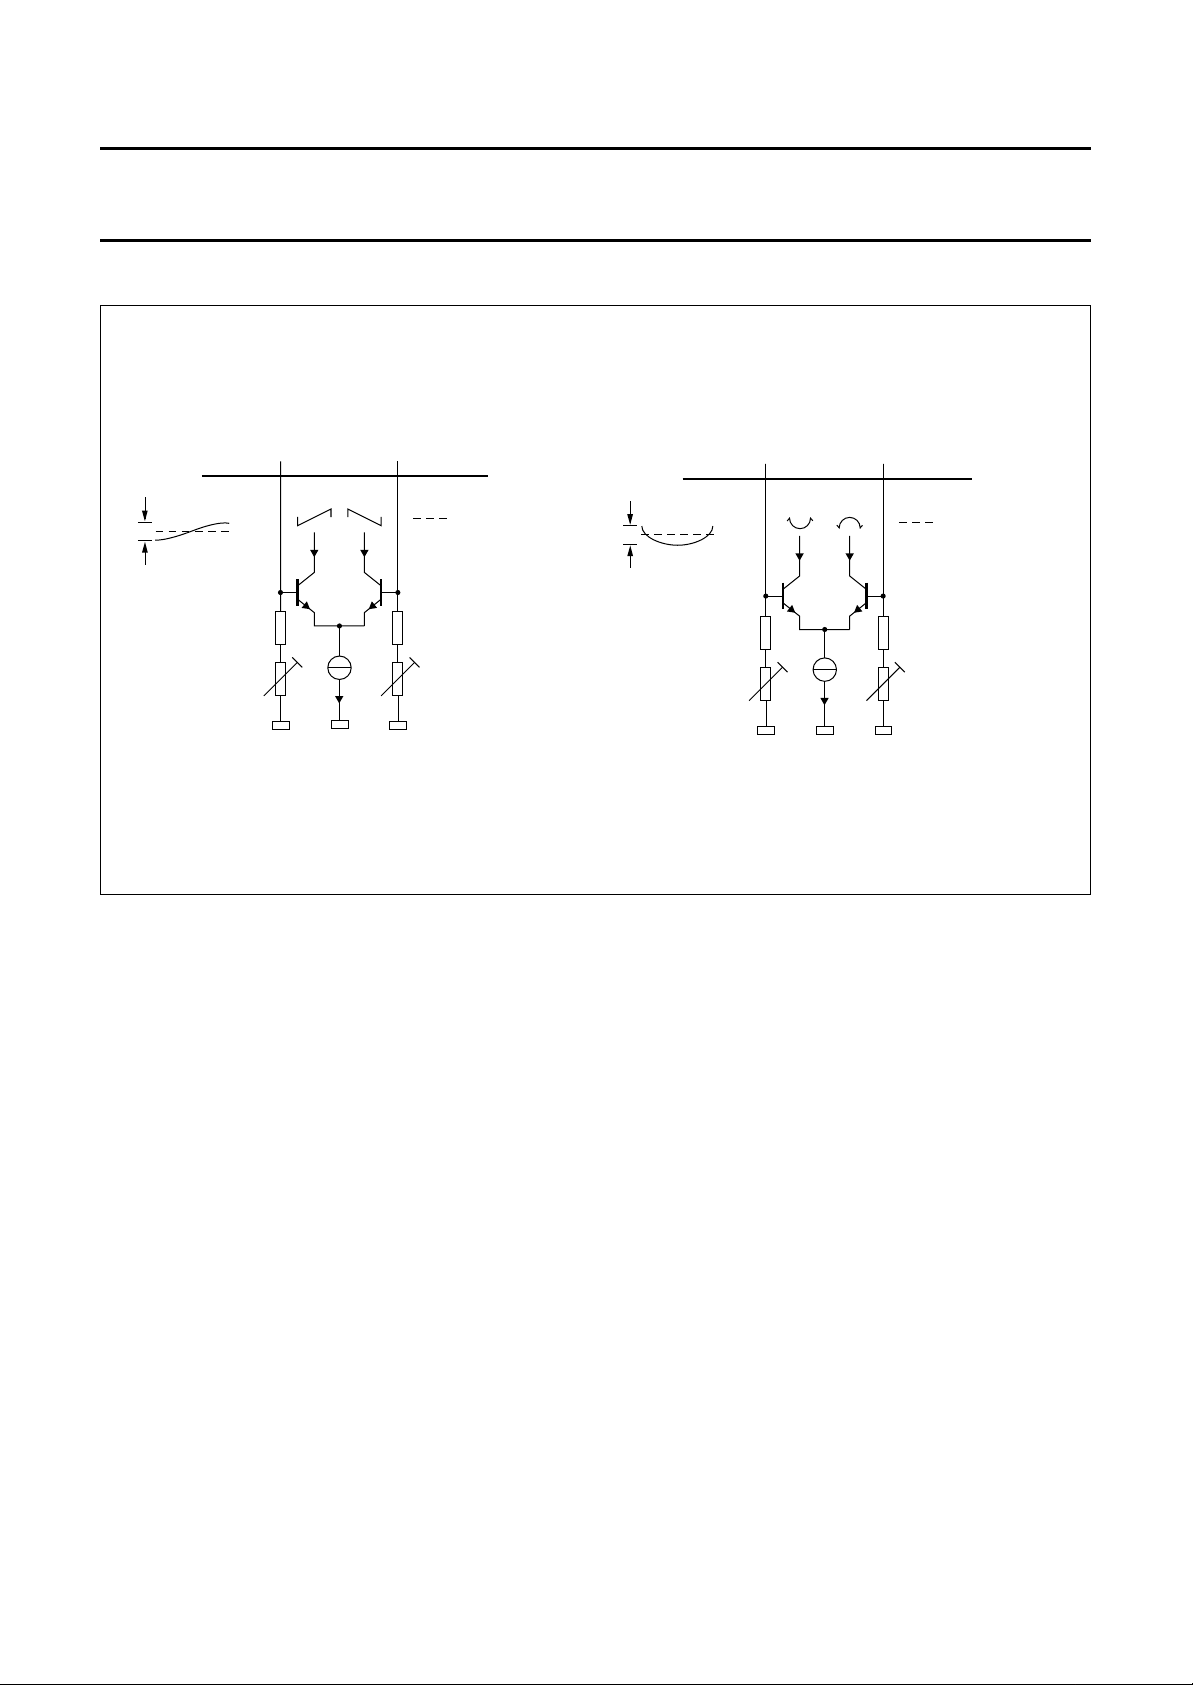
Application hint: VSCOR is a current input at 5 V.
Superimposed on this level is a very small positive-going
vertical sawtooth, intended to modulate an external
long-tailed transistor pair. This enables further optional DC
controls of functions which are not directly accessible such
as vertical tilt or vertical linearity (see Fig.17).
EW parabola (including horizontal size and trapezium correction)
EWDRV (pin 11) provides a complete EW drive waveform.
EW parabola amplitude, DC shift (horizontal size) and
trapezium correction can be controlled via separate DC
inputs.
EWPAR (pin 21) is used to adjust the parabola amplitude.
This can be a combination of a DC adjustment and a
dynamic waveform modulation.
The EW parabola amplitude also tracks with vertical
picture size. The parabola waveform itself tracks with the
adjustment for vertical picture shift (VPOS).
Additional effort has been taken to generate a smooth
waveform at the top of the parabola. This is to avoid ringing
in the horizontal output stage.
EWWID (pin 32) offers two modes of operation:
1. Mode 1
Horizontal size is DC controlled via EWWID (pin 32)
and causes a DC shift at the EWDRV output. Also the
complete waveform is multiplied internally by a signal
proportional to the line frequency (which is detected
via the current at HREF (pin 28). This mode is to be
used for driving EW modulator stages which require a
voltage proportional to the line frequency.
2. Mode 2
EWWID (pin 32) is grounded. Then EWDRV is no
longer multiplied by the line frequency. The DC
adjustment for horizontal size must be added to the
input of the B+ control amplifier BIN (pin 5). This mode
is to be used for driving EW modulators which require
a voltage independent of the line frequency.
EWTRP (pin 20) is used to adjust the amount of trapezium
correction in the EW drive waveform.
1996 Jul 18 9
Page 10
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
Application hint: EWTRP (pin 20) is a current input at
5 V. Superimposed on this level is a very small vertical
parabola with positive tips, intended to modulate an
external long-tailed transistor pair. This enables further
optional DC controls of functions which are not directly
accessible such as EW-corner, vertical focus or EW pin
balance (see Fig.17).
Application hint: By grounding EWTRP (pin 20) the
symmetrical control range is forced to its centre value.
Dynamic focus section
This section generates a horizontal parabola waveform for
dynamic focus applications. The amplitude of this parabola
is internally stabilized, thus it is independent from the line
frequency.
FOCUS (pin 10) is designed as a current sink.
The peak-to-peak amplitude of the output current can be
adjusted by forcing the voltage at pin 10 to a value
between 1 and 4 V.
B+ control function block
The B+ control function block of the ASDC consists of an
Operational Transconductance Amplifier (OTA), a voltage
comparator, a flip-flop and a discharge circuit.
This configuration allows easy applications for different
B+ control concepts.
ENERAL DESCRIPTION
G
The non-inverting input of the OTA is connected internally
to a high precision reference voltage. The inverting input is
connected to BIN (pin 5). An internal clamping circuit limits
the maximum positive output voltage of the OTA.
The output itself is connected to BOP (pin 3) and to the
inverting input of the voltage comparator.
The non-inverting input of the voltage comparator can be
accessed via BSENS (pin 4).
B+ drive pulses are generated by an internal flip-flop and
fed to BDRV (pin 6) via an open collector output stage.
This flip-flop will be set at the rising edge of the signal at
HDRV (pin 7). The falling edge of the output signal at
BDRV has a defined delay of t
to the rising edge of
d(BDRV)
the HDRV pulse. When the voltage at BSENS exceeds the
voltage at BOP, the voltage comparator output resets the
flip-flop, and therefore the open collector stage at BDRV is
floating again.
An internal discharge circuit allows a well defined
discharge of capacitors at BSENS. BDRV is active at a low
level output voltage (see Figs 12 and 13), thus it requires
an external inverting driver stage.
The B+ function block can be used for B+ deflection
modulators in either of two modes:
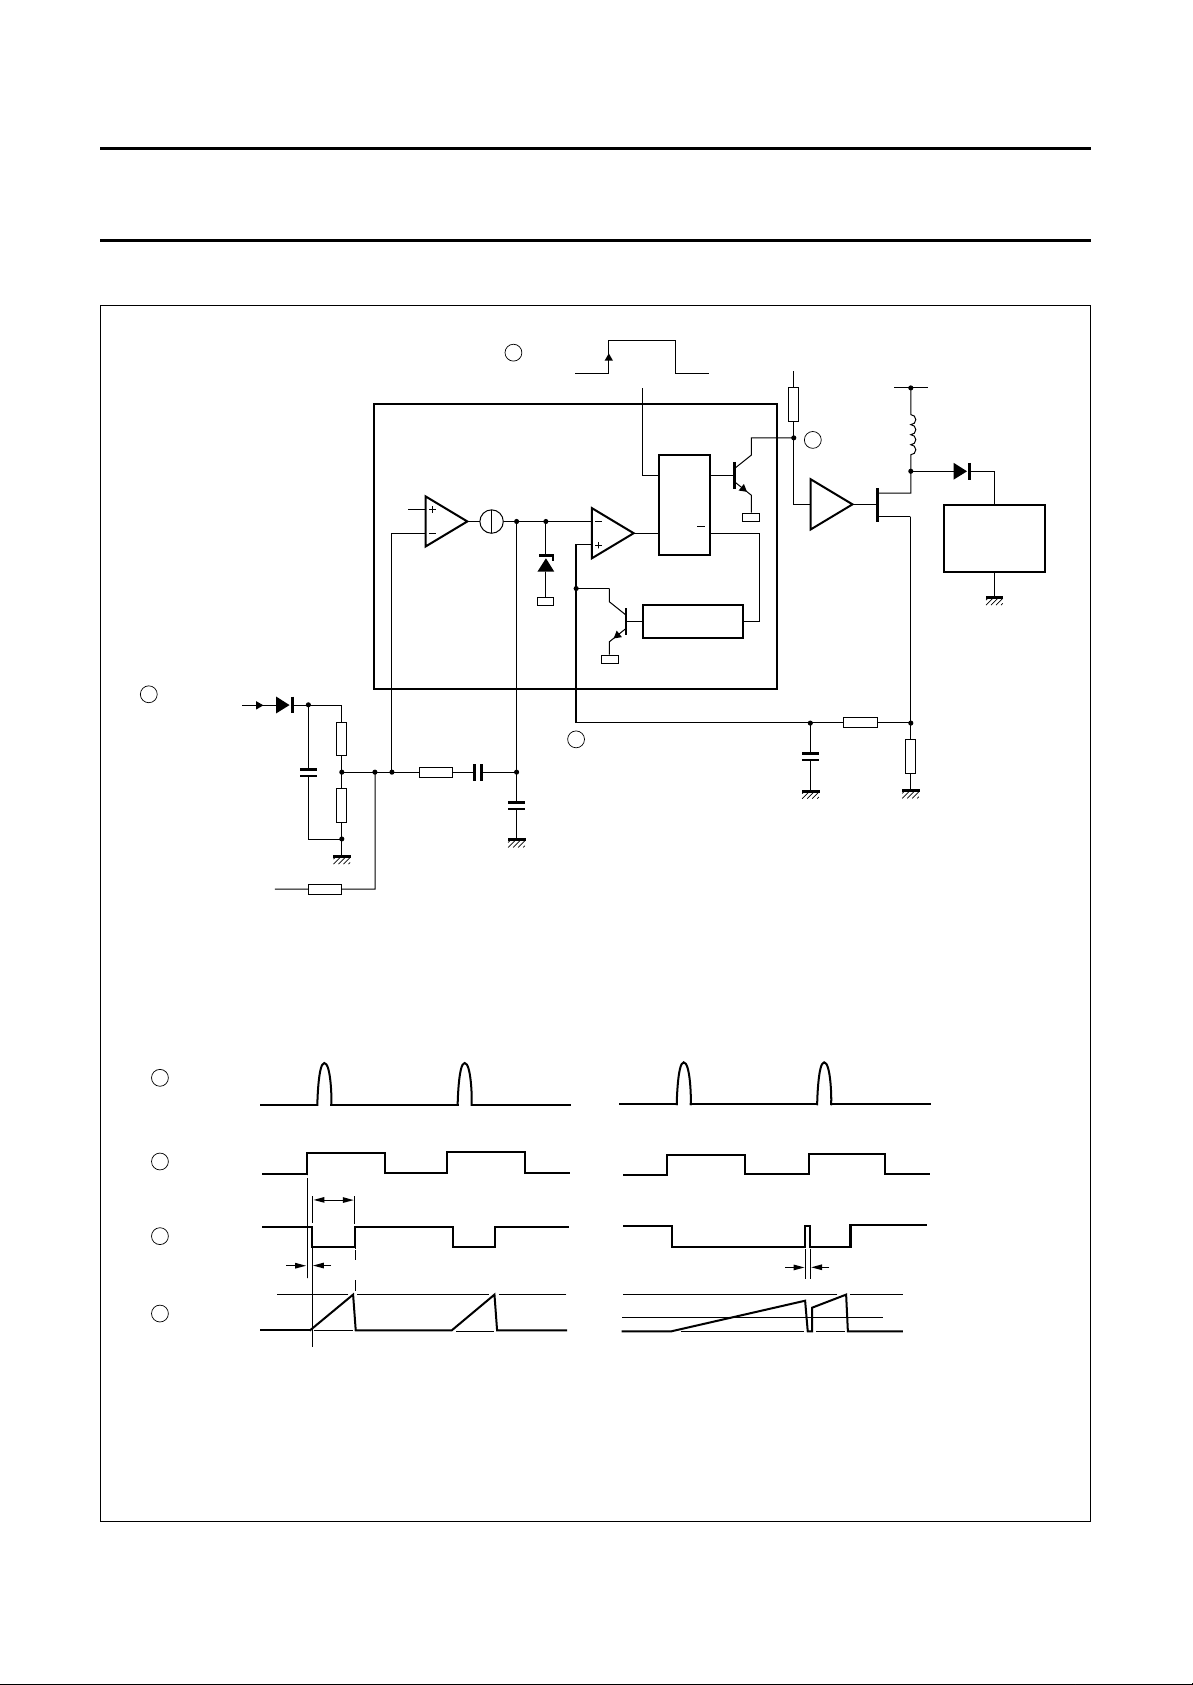
• Feedback mode (see Fig.12)
In this application the OTA is used as an error amplifier
with a limited output voltage range. The flip-flop will be
set at the rising edge of the signal at HDRV. A reset will
be generated when the voltage at BSENS taken from
the current sense resistor exceeds the voltage at BOP.
If no reset is generated within a line period, the rising
edge of the next HDRV pulse forces the flip-flop to reset.
The flip-flop is set immediately after the voltage at
BSENS has dropped below the threshold voltage
V
RESTART(BSENS)
.
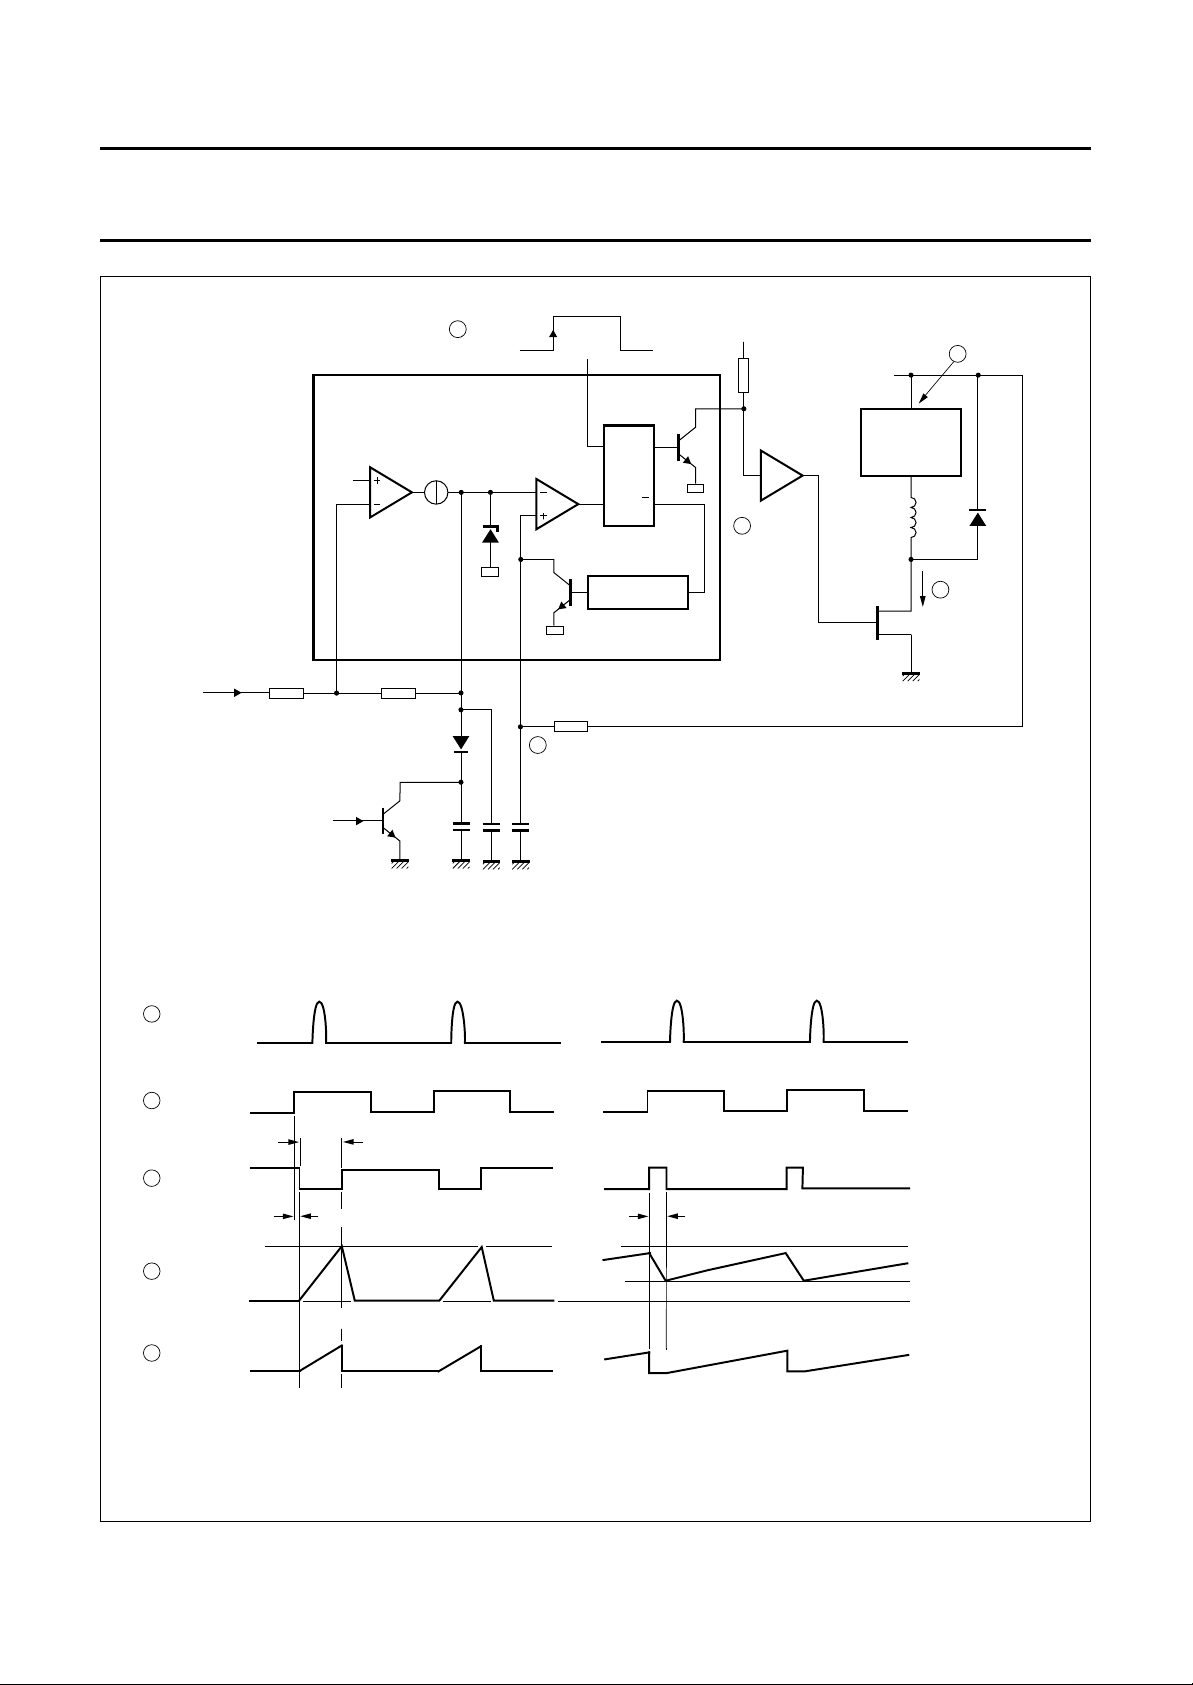
• Feed forward mode (see Fig.13)
This application uses an external RC combination at
BSENS to provide a pulse width which is independent
from the horizontal frequency. The capacitor is charged
via an external resistor and discharged by the internal
discharge circuit. For normal operation the discharge
circuit is activated when the flip-flop is reset by the
internal voltage comparator. Now the capacitor will be
discharged with a constant current until the internally
controlled stop level V
STOP(BSENS)
is reached. This level
will be maintained until the rising edge of the next HDRV
pulse sets the flip-flop again and disables the discharge
circuit.
If no reset is generated within a line period, the rising
edge of the next HDRV pulse automatically starts the
discharge sequence and resets the flip-flop (Fig.13).
When the voltage at BSENS reaches the threshold
voltage V
RESTART(BSENS)
, the discharge circuit will be
disabled automatically and the flip-flop will be set
immediately. This behaviour allows a definition of the
maximum duty cycle of the B+ control drive pulse by the
relationship of charge current to discharge current.
1996 Jul 18 10
Page 11
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
Supply voltage stabilizer, references and protection
The ASDC provides an internal supply voltage stabilizer
for excellent stabilization of all internal references.
An internal gap reference especially designed for
low-noise is the reference for the internal horizontal and
vertical supply voltages. All internal reference currents and
drive current for the vertical output stage are derived from
this voltage via external resistors.
A special protection mode has been implemented in order
to protect the deflection stages and the picture tube during
start-up, shut-down and fault conditions. This protection
mode can be activated as shown in Table 4.
Table 4 Activation of protection mode
ACTIVATION RESET
Low supply voltage at pin 9 increase supply voltage
X-ray protection XRAY (pin 2)
triggered
HPLL2 (pin 31) pulled to
ground
When protection mode is active, several pins of the ASDC
are forced into a defined state:
HDRV (horizontal driver output) is floating
BDRV (B+ control driver output) is floating
VOUT1 and VOUT2 (vertical outputs) are floating
CLBL provides a continuous blanking signal
The capacitor at HPLL2 is discharged.
remove supply voltage
release pin 31
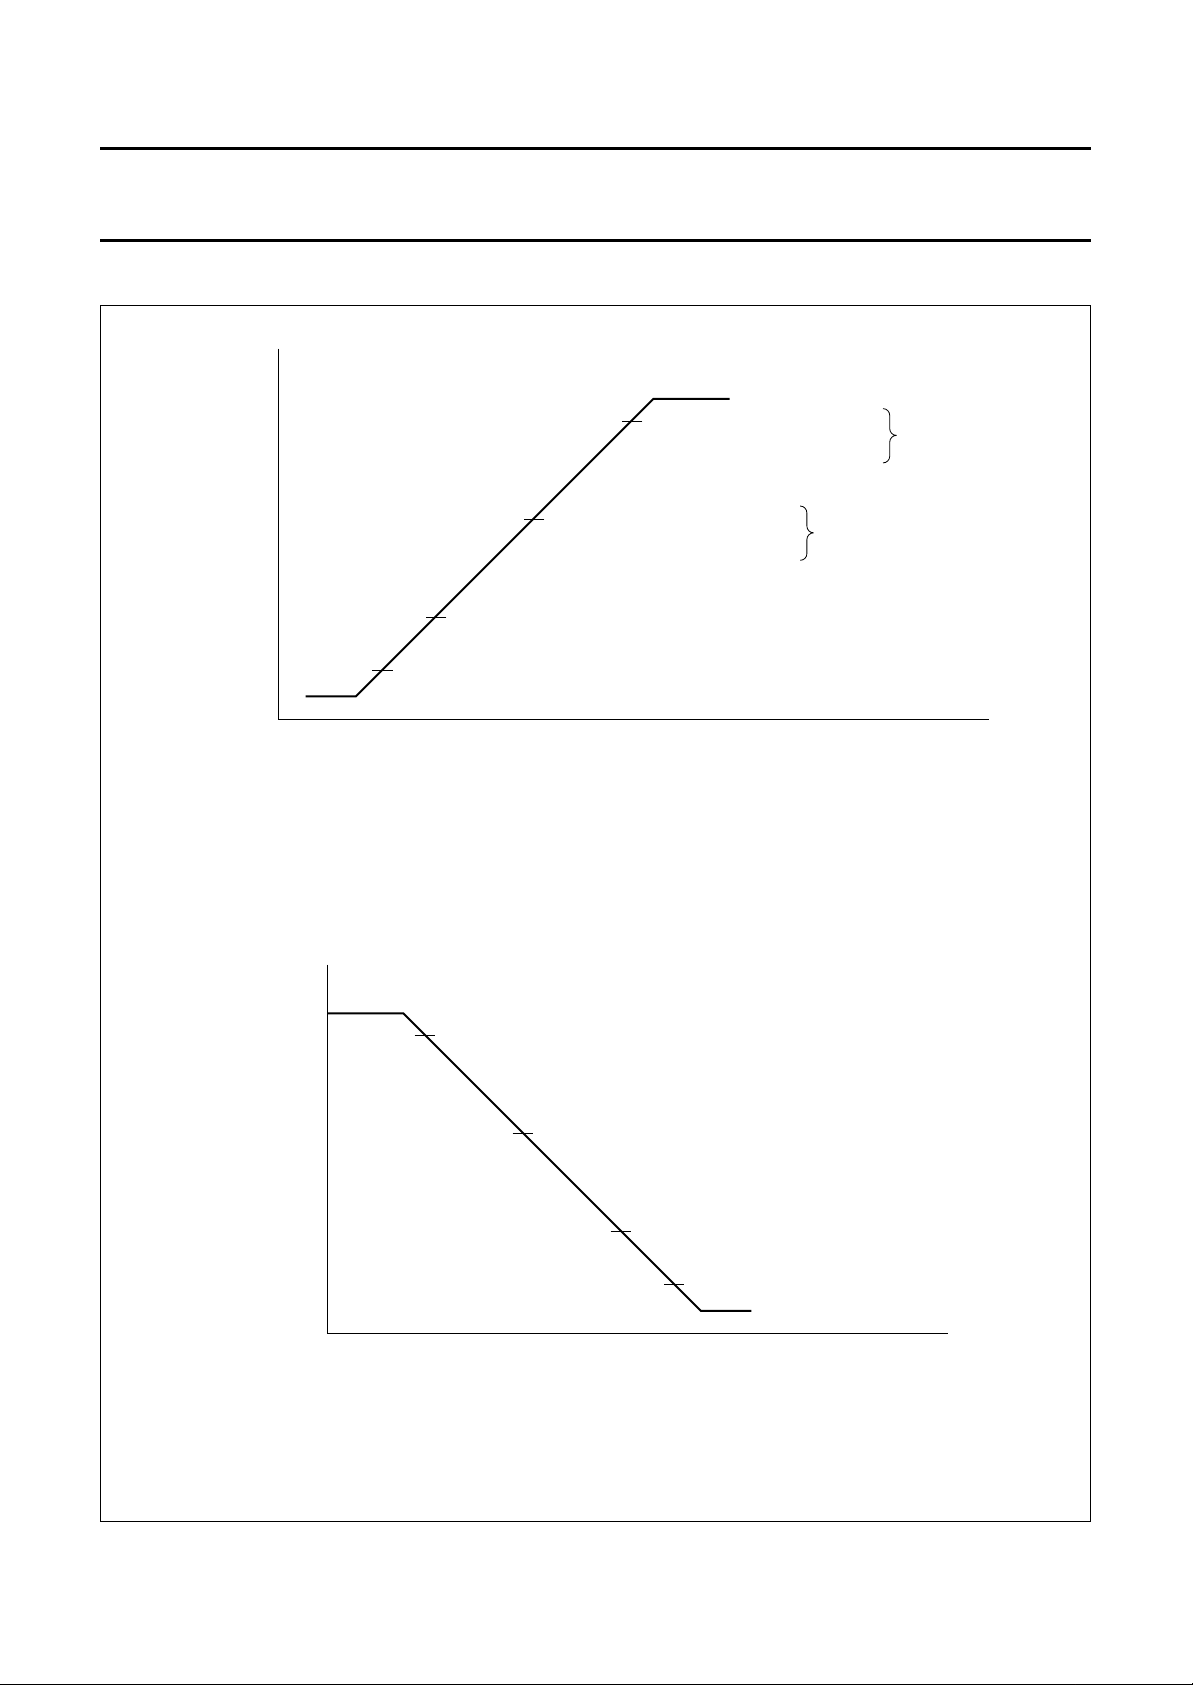
The return to normal operation is performed in accordance
with the start-up sequence in Fig.14a, if the reset was
caused by the supply voltage at pin 9. The first action with
increasing supply voltage is the activation of continuous
blanking at CLBL. When the threshold for activation of
HDRV is passed, an internal current begins to charge the
external capacitor at HPLL2 and a PLL2 soft start
sequence is performed (see Fig.15). In the beginning of
this phase the horizontal driver stage generates very small
output pulses. The width of these pulses increases with the
voltage at HPLL2 until the final duty cycle is reached.
Then the PLL2 voltage passes the threshold for activation
of BDRV, VOUT1 and VOUT2.
For activation of these pins not only the PLL2 voltage, but
also the supply voltage must have passed the appropriate
threshold. A last pair of thresholds has to be passed by
PLL2 voltage and supply voltage before the continuous
blanking is finally removed, and the operation of PLL2 and
frequency-locked loop is enabled.
A return to the normal operation by releasing the voltage
at HPLL2 will lead to a slightly different sequence. Here the
activation of all functions is influenced only by the voltage
at HPLL2 (see Fig.15).
Application hint: Internal discharge of the capacitor at
HPLL2 will only be performed, if the protection mode was
activated via the supply voltage or X-ray protection.
If the protection mode is activated via the supply voltage at
pin 9, all these actions will be performed in a well defined
sequence (see Fig.14). For activation via X-ray protection
or HPLL2 all actions will occur simultaneously.
1996 Jul 18 11
Page 12
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
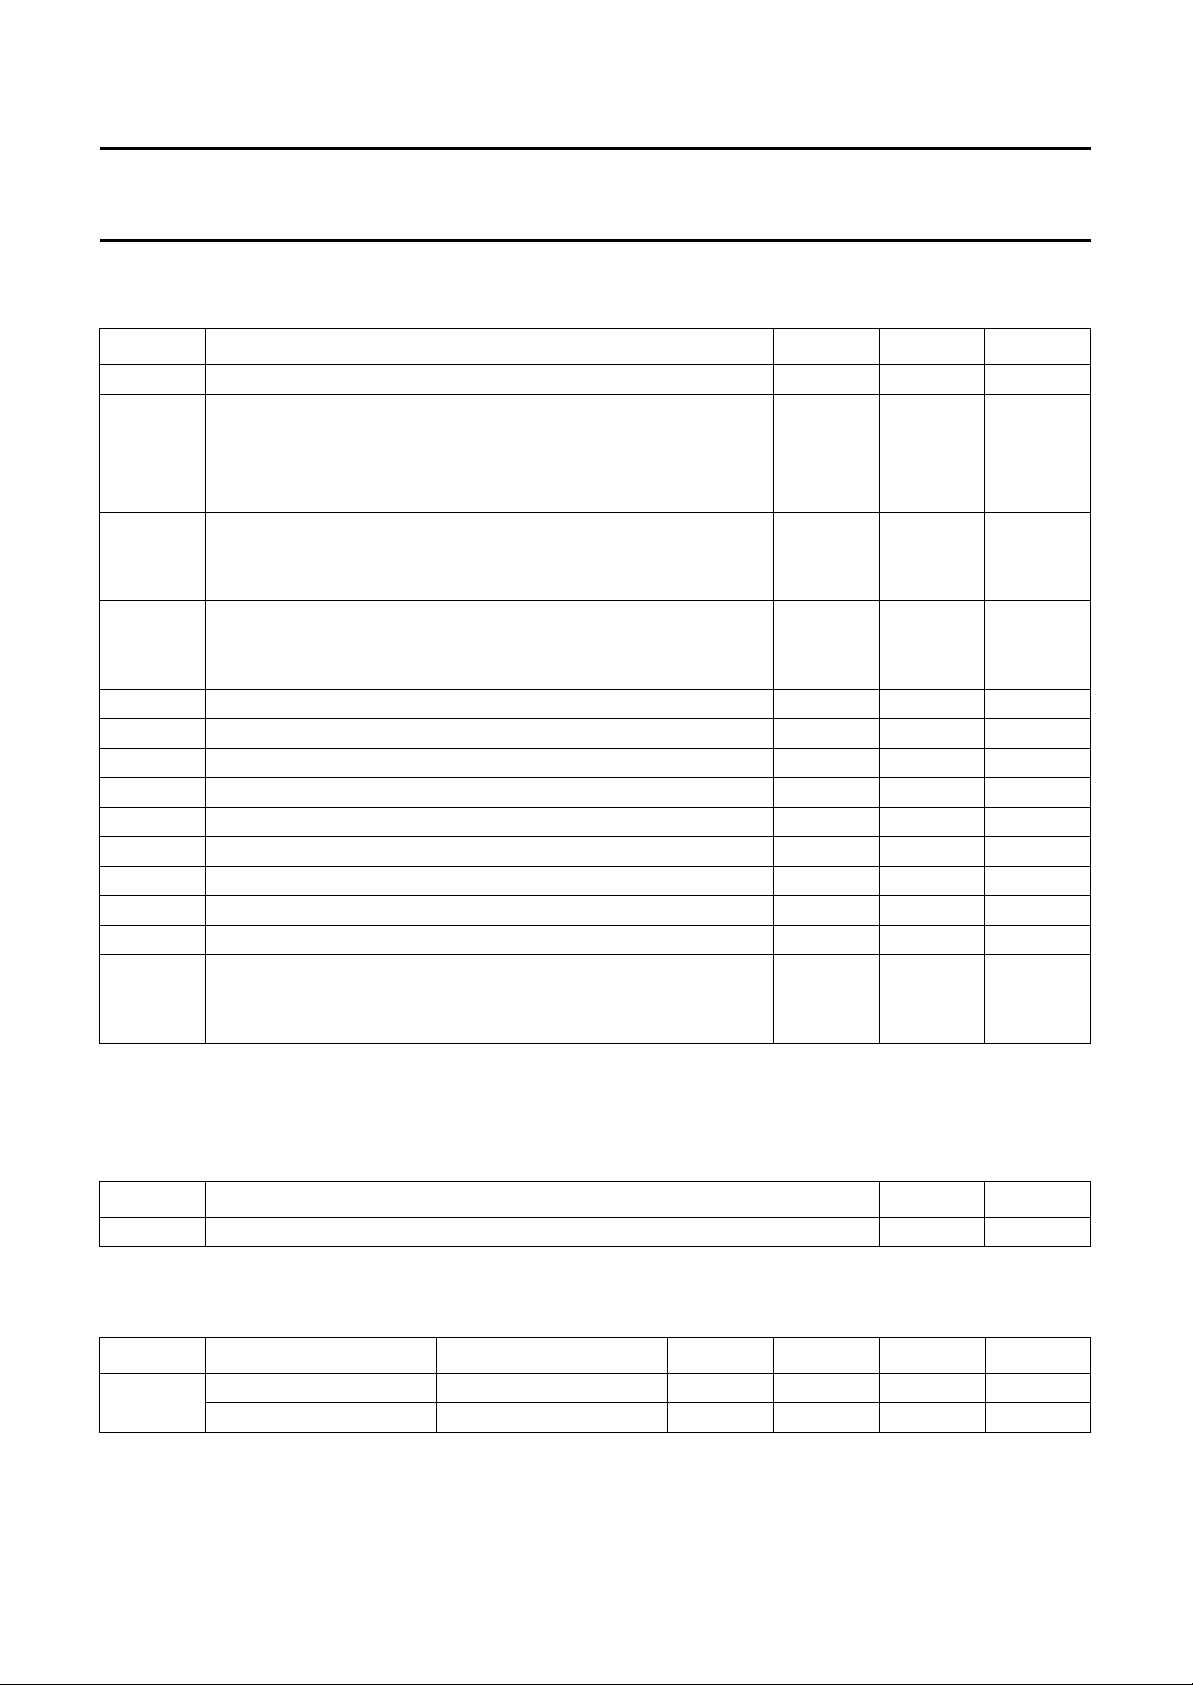
LIMITING VALUES
In accordance with the Absolute Maximum Rating System (IEC 134); all voltages measured with respect to ground.
SYMBOL PARAMETER MIN. MAX. UNIT
V
CC
V
I(n)
V
O(n)
V
I/O(n)
I
HDRV
I
HFLB
I
CLBL
I
BOP
I
BDRV
I
EWDRV
T
amb
T
j
T
stg
V
esd
supply voltage −0.5 +16 V
input voltages
BIN −0.5 +6.0 V
HSYNC, VPOS, VAMP, VSCOR, VREF, HREF and HPOS −0.5 +6.5 V
XRAY −0.5 +8.0 V
output voltages
VOUT1 and VOUT2 −0.5 +6.5 V
BDRV and HDRV −0.5 +16 V
input/output voltages
BOP and BSENS −0.5 +6.0 V
FOCUS and VSYNC −0.5 +6.5 V
horizontal driver output current − 100 mA
horizontal flyback input current −10 +10 mA
video clamping pulse/vertical blanking output current −−10 mA
B+ control OTA output current − 1mA
B+ control driver output current − 50 mA
EW driver output current −−5mA
operating ambient temperature 0 70 °C
junction temperature − 150 °C
storage temperature −55 +150 °C
electrostatic discharge for all pins (note 1)
machine model −400 +400 V
human body model −3000 +3000 V
Note
1. Machine model: 200 pF, 25 Ω, 2.5 µH; human body model: 100 pF, 1500 Ω, 7.5 µH.
THERMAL CHARACTERISTICS
SYMBOL PARAMETER VALUE UNIT
R
th j-a
thermal resistance from junction to ambient in free air 55 K/W
QUALITY SPECIFICATION
In accordance with
“URF-4-2-59/601”
; EMC emission/immunity test in accordance with
“DIS 1000 4.6”
(IEC 801.6)
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
V
EMC
emission test note 1 − 1.5 − mV
immunity test note 1 − 2.0 − V
Note
1. Tests are performed with application reference board. Tests with other boards will have different results.
1996 Jul 18 12
Page 13
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
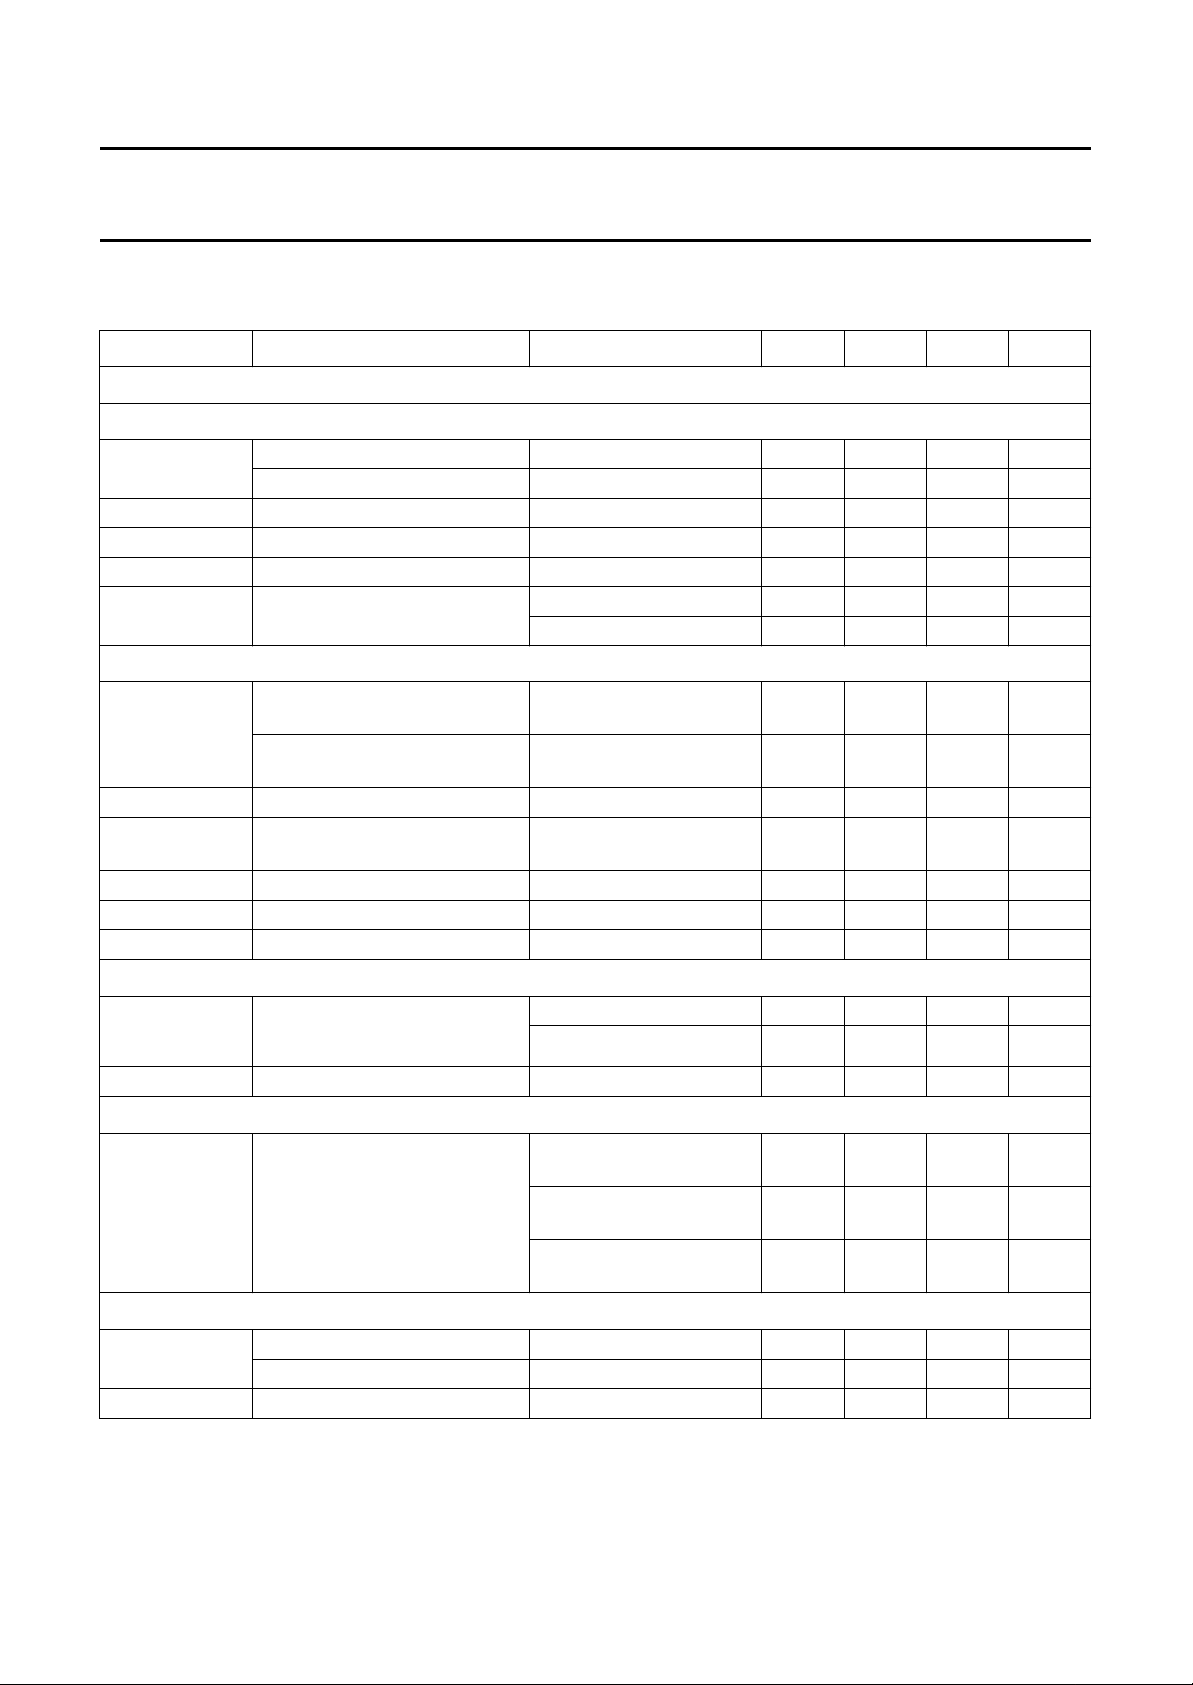
CHARACTERISTICS
V
=12V; T
CC
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
Horizontal sync separator
I
NPUT CHARACTERISTICS FOR DC-COUPLED TTL SIGNALS [HSYNC (PIN 15)]
V
DC(HSYNC)
t
r(HSYNC)
t
f(HSYNC)
t
W(HSYNC)
I
DC(HSYNC)
INPUT CHARACTERISTICS FOR AC-COUPLED VIDEO SIGNALS (SYNC-ON-VIDEO, NEGATIVE SYNC POLARITY)
V
AC(HSYNC)
V
clamp(HSYNC)
I
C(HSYNC)
t
HSYNC(min)
R
S(max)
r
diff(HSYNC)
Automatic polarity correction for horizontal sync
t
PH()
------------t
H
t
P(H)
Vertical sync integrator
t
int(V)
Vertical sync slicer (DC-coupled, TTL compatible) [VSYNC (pin 14)]
V
VSYNC
I
VSYNC
=25°C; peripheral components in accordance with Fig.1; unless otherwise specified.
amb
sync input signal voltage 1.7 −−V
slicing voltage level 1.2 1.4 1.6 V
rise time of sync pulse 10 − 500 ns
fall time of sync pulse 10 − 500 ns
minimum width of sync pulse 0.7 −−µs
input current V
V
sync amplitude of video input
= 0.8 V −−−200 µA
HSYNC
= 5.5 V −−10 µA
HSYNC
− 300 − mV
signal voltage
slicing voltage level
(measured from top sync)
source resistance
R
=50Ω
S
90 120 150 mV
top sync clamping voltage level 1.1 1.28 1.5 V
charge current for coupling
V
HSYNC
> V
clamp(HSYNC)
1.7 2.4 3.4 µA
capacitor
minimum width of sync pulse 0.7 −−µs
maximum source resistance duty factor = 7% −−1500 Ω
differential input resistance during sync − 80 −Ω
horizontal sync pulse width
related to t
H
fH< 45 kHz −−20 %
> 45 kHz −−25 %
f
H
delay time for changing polarity 0.3 − 1.8 ms
integration time for generation
of a vertical trigger pulse
fH= 31.45 kHz;
I
= 1.052 mA
HREF
= 64 kHz;
f
H
I
= 2.141 mA
HREF
= 100 kHz;
f
H
I
= 3.345 mA
HREF
71013µs
3.9 5.7 6.5 µs
2.5 3.8 4.5 µs
sync input signal voltage 1.7 −−V
slicing voltage level 1.2 1.4 1.6 V
input current 0 V < V
< 5.5 V −−±10 µA
SYNC
1996 Jul 18 13
Page 14
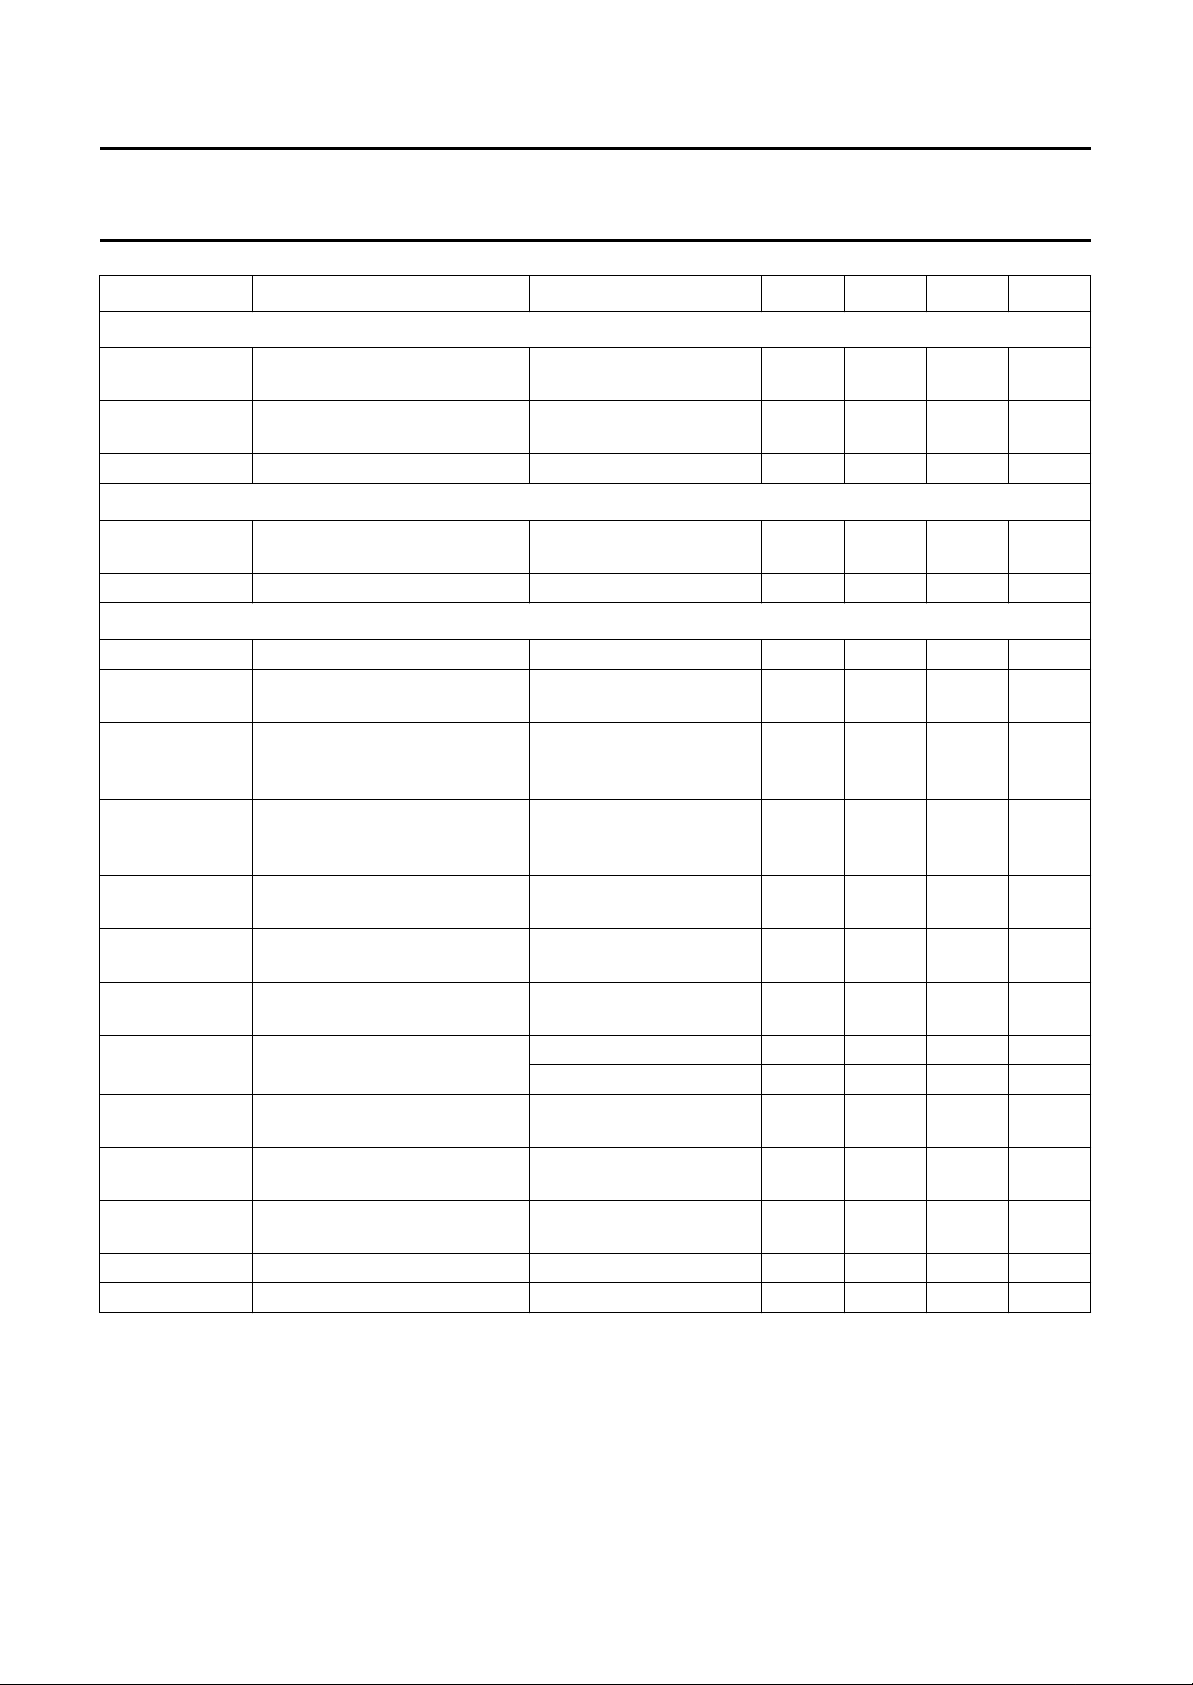
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
VERTICAL SYNC OUTPUT AT VSYNC (PIN 14) DURING COMPOSITE SYNC AT HSYNC (PIN 15)
I
VSYNC
output current during internal vertical
sync
V
VSYNC
internal clamping voltage level during internal vertical
sync
steepness of slopes − 300 − ns/mA
Automatic polarity correction for vertical sync
t
VSYNC(max)
maximum width of vertical sync
pulse
t
d(VPOL)
delay for changing polarity 0.3 − 1.8 ms
Video clamping/vertical blanking output [CLBL (pin 16)]
t
clamp(CLBL)
V
clamp(CLBL)
width of video clamping pulse measured at V
top voltage level of video
clamping pulse
t
d(clamp)
t
clamp(max)
delay between trailing edge of
horizontal sync and start of
video clamping pulse
maximum duration of video
clamping pulse triggered
on trailing edge of
horizontal sync
measured at V
clamping pulse referenced to
end of horizontal sync
TC
clamp
temperature coefficient of
V
clamp(CLBL)
steepness of slopes for
=1MΩ; CL=20pF − 50 − ns/V
R
L
clamping pulse
V
blank(CLBL)
top voltage level of vertical
notes 1 and 2 1.7 1.9 2.1 V
blanking pulse
t
blank(CLBL)
width of vertical blanking pulse VGA presets active 500 575 650 µs
VGA presets disabled 240 300 360 µs
TC
blank
V
scan(CLBL)
temperature coefficient of
V
blank(CLBL)
output voltage during vertical
I
= 0 0.59 0.63 0.67 V
CLBL
scan
TC
scan
I
sink(CLBL)
I
load(CLBL)
temperature coefficient of
V
scan(CLBL)
internal sink current 2.4 −−mA
external load current −−−3.0 mA
= 3 V 0.6 0.7 0.8 µs
CLBL
=3V −−1.0 µs
CLBL
−0.7 −1.0 −1.35 mA
4.4 4.8 5.2 V
−−300 µs
4.32 4.75 5.23 V
− 130 − ns
− +4 − mV/K
− +2 − mV/K
−−2−mV/K
1996 Jul 18 14
Page 15
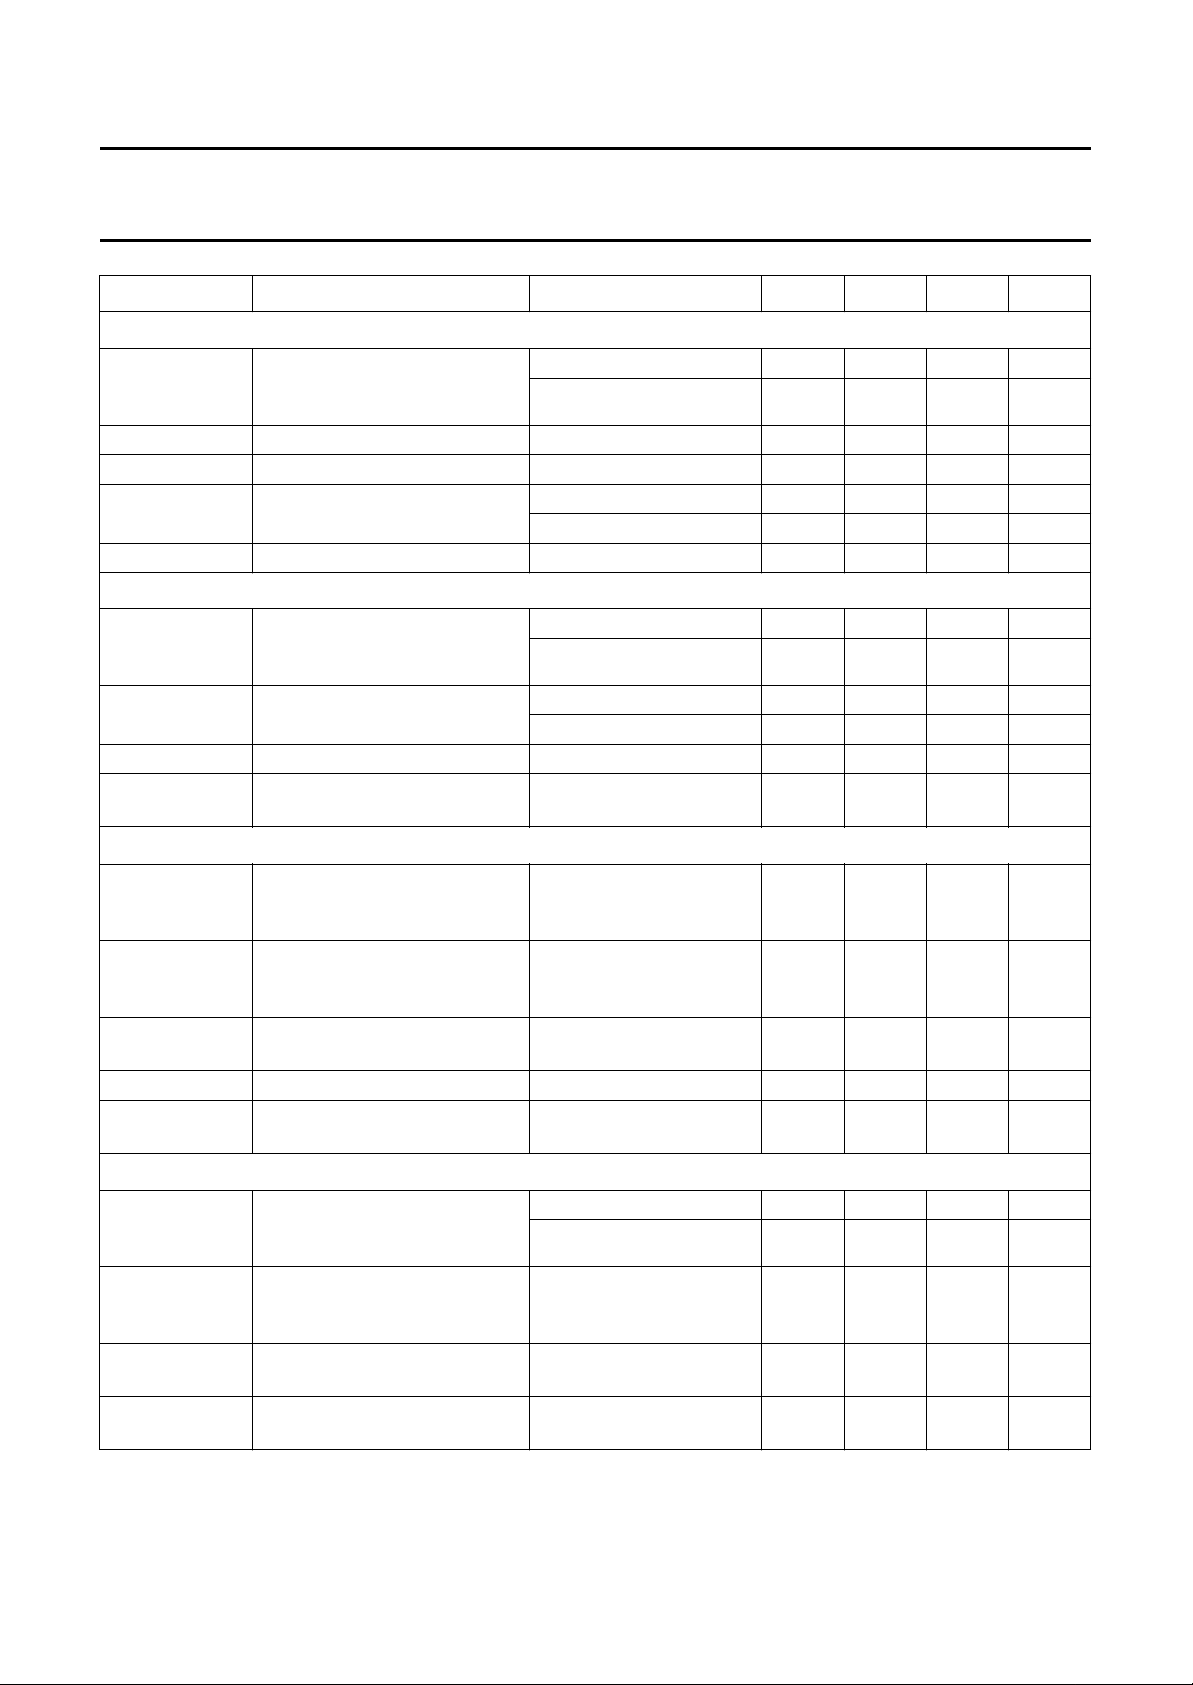
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
PLL1 phase comparator and frequency-locked loop [HPLL1 (pin 26) and HBUF (pin 27)]
t
HSYNC(max)
maximum width of horizontal
sync pulse (referenced to line
period)
t
lock(HPLL1)
V
HPLL1
V
HBUF
total lock-in time of PLL1 − 40 80 ms
control voltage notes 4 and 5
buffered f/v voltage at HBUF
(pin 27)
I
load(HBUF)
maximum load current −−−4.0 mA
ADJUSTMENT OF HORIZONTAL PICTURE POSITION
∆HPOS horizontal shift adjustment
range (referenced to horizontal
period)
I
HPOS
V
ref(HPOS)
V
off(HPOS)
input current ∆HPOS = +10.5% −110 −120 −135 µA
reference voltage at input note 7 − 5.1 − V
picture shift is centred if HPOS
(pin 30) is forced to ground
fH< 45 kHz; note 3 −−20 %
> 45 kHz; note 3 −−25 %
f
H
f
; note 6 − 5.6 − V
H(min)
; note 6 − 2.5 − V
f
H(max)
I
I
=0 −−10.5 − %
HSHIFT
= −135 µA − +10.5 − %
HSHIFT
∆HPOS = −10.5% − 0 −µA
0 − 0.1 V
Horizontal oscillator [HCAP (pin 29) and HREF (pin 28)]
f
H(0)
∆f
H(0)
free-running frequency without
PLL1 action (for testing only)
spread of free-running
R
HBUF
R
HREF
C
HCAP
frequency (excluding spread of
external components)
TC temperature coefficient of
free-running frequency
f
H(max)
V
HREF
maximum oscillator frequency −−130 kHz
voltage at input for reference
current
PLL2 phase detector [HFLB (pin 1) and HPLL2 (pin 31)]
∆φ
PLL2
PLL2 control (advance of
horizontal drive with respect to
maximum advance 36 −−%
minimum advance − 7 − %
middle of horizontal flyback)
t
d(HFLB)
delay between middle of
HPOS (pin 30) grounded − 200 − ns
horizontal sync and middle of
horizontal flyback
V
PROT(HPLL2)
maximum voltage for PLL2
protection mode/soft start
I
charge(HPLL2)
charge current for external
V
HPLL2
capacitor during soft start
= ∞;
30.53 31.45 32.39 kHz
= 2.4 kΩ;
= 10 nF; note 5
−−±3.0 %
−6
−100 0 +100 10
/K
2.43 2.55 2.68 V
− 4.4 − V
< 3.7 V − 15 −µA
1996 Jul 18 15
Page 16
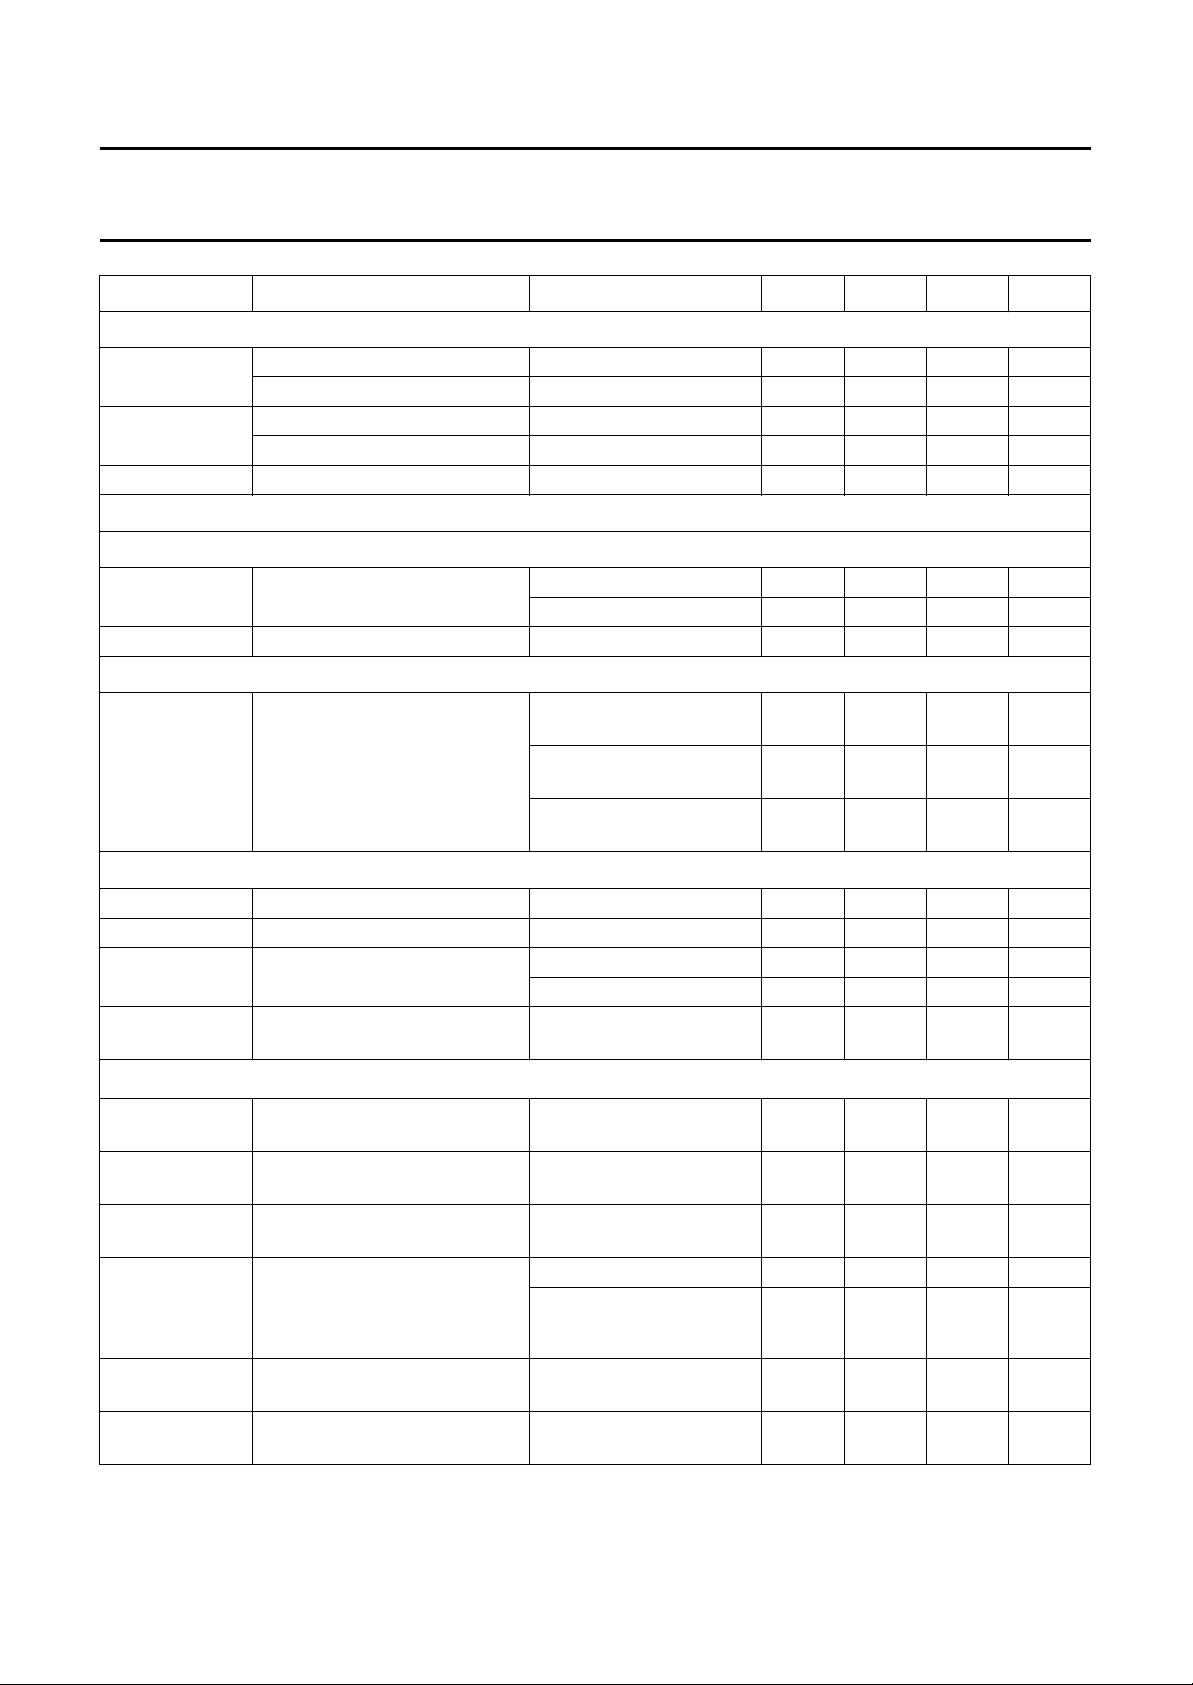
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
HORIZONTAL FLYBACK INPUT [HFLB (PIN 1)]
V
HFLB
positive clamping level I
negative clamping level I
I
HFLB
positive clamping current −−6mA
negative clamping current −−−2mA
V
HFLB
slicing level − 2.8 − V
Output stage for line driver pulses [HDRV (pin 7)]
PEN COLLECTOR OUTPUT STAGE
O
V
HDRV
I
leakage(HDRV)
saturation voltage I
output leakage current V
AUTOMATIC VARIATION OF DUTY FACTOR
t
HDRV(OFF)/tH
relative t
time of HDRV
OFF
output; measured at
V
= 3 V; HDRV duty factor
HDRV
is determined by the relation
I
HREF/IVREF
=5mA − 5.5 − V
HFLB
= −1mA −−0.75 − V
HFLB
=20mA −−0.3 V
HDRV
=60mA −−0.8 V
I
HDRV
=16V −−10 µA
HDRV
I
HDRV
=20mA;
42 45 48 %
fH= 31.45 kHz; see Fig.9
I
HDRV
=20mA;
45 46.3 47.7 %
fH= 57 kHz; see Fig.9
I
HDRV
=20mA;
46.6 48 49.4 %
fH= 90 kHz; see Fig.9
X-ray protection [XRAY (pin 2)]
V
XRAY
t
W(XRAY)
R
I(XRAY)
V
RESET(VCC)
slicing voltage level 6.14 6.38 6.64 V
minimum width of trigger pulse 10 −−µs
input resistance at XRAY
(pin 2)
supply voltage for reset of
V
< 6.38 V + V
XRAY
> 6.38 V + V
V
XRAY
BE
BE
500 −−kΩ
− 5 − kΩ
− 5.6 − V
X-ray latch
Vertical oscillator (oscillator frequency in application without adjustment of free-running frequency f
f
f
V
V
v(o)
VREF
free-running frequency R
vertical frequency catching
range
voltage at reference input for
=22kΩ;
VREF
C
= 100 nF
VCAP
constant amplitude;
notes 8, 9 and 10
40 42 43.3 Hz
50 − 110 Hz
− 3.0 − V
vertical oscillator
t
d(scan)
delay between trigger pulse
and start of ramp at VCAP
VGA presets active 500 575 650 µs
VGA presets disabled 240 300 360 µs
(pin 24) (width of vertical
blanking pulse)
I
VAGC
control currents of amplitude
±120 ±200 ±300 µA
control
C
VAGC
external capacitor at VAGC
−−150 nF
(pin 22)
v(o)
)
1996 Jul 18 16
Page 17
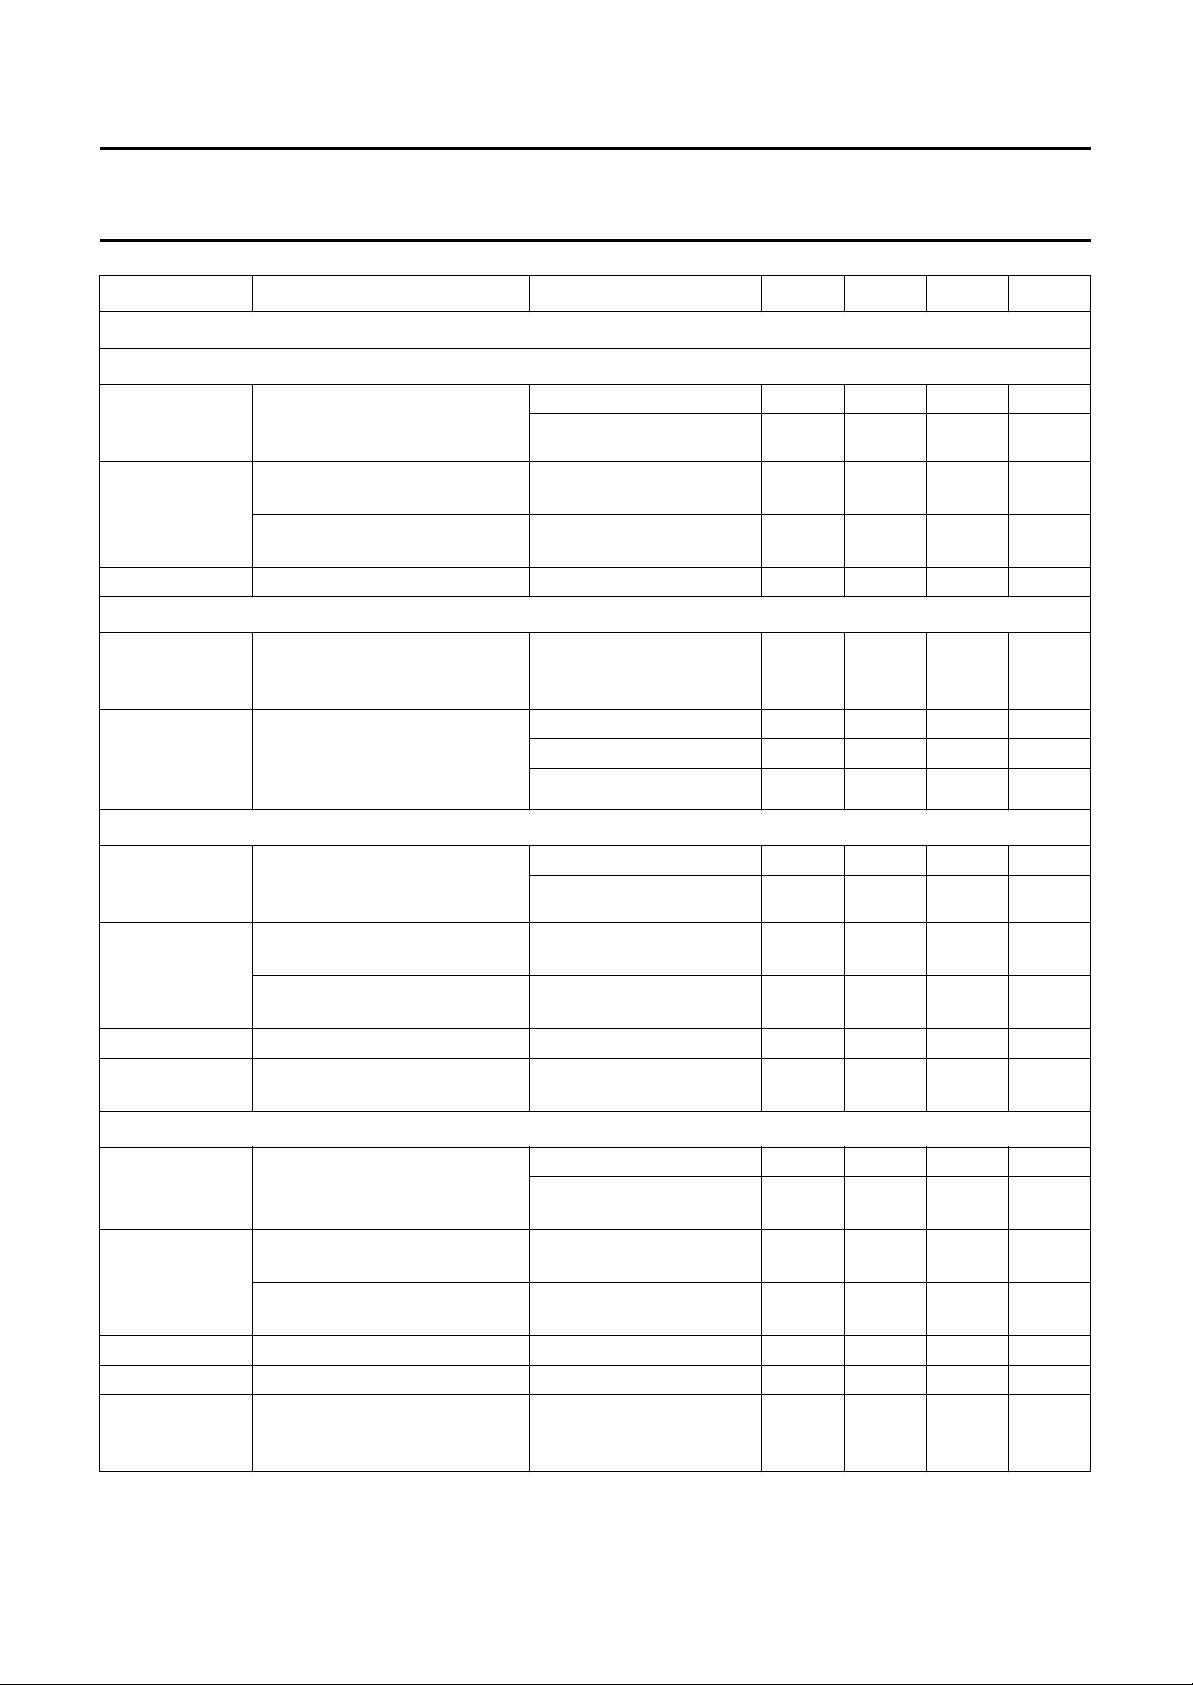
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
Differential vertical current outputs
ADJUSTMENT OF VERTICAL SIZE (see Figs 3 to 8) [VAMP (PIN 18)]
∆VAMP vertical size adjustment range
(referenced to nominal vertical
size)
I
VAMP
input current for maximum
amplitude (100%)
input current for minimum
amplitude (60%)
V
ref(VAMP)
reference voltage at input − 5.0 − V
PRESETS FOR VGA MODE DEPENDENT VERTICAL SIZE
I
HBUF/IHREF
minimum current ratio
I
HBUF/IHREF
for enable of VGA
presets
∆VAMP variation of vertical size for
detected VGA modes
(reference for all amplitude
settings is VGA480 mode)
DJUSTMENT OF VERTICAL SHIFT (see Figs 3 to 8) [VPOS (PIN 17)]
A
∆VPOS vertical shift adjustment range
(referenced to 100% vertical
size)
I
VPOS
input current for maximum
shift-up
input current for maximum
shift-down
V
ref(VPOS)
V
off(VPOS)
reference voltage at input − 5.0 − V
vertical shift is centred if VPOS
(pin 17) is forced to ground
ADJUSTMENT OF VERTICAL S-CORRECTION (see Figs 3 to 8) [VSCOR (PIN 19)]
∆VSCOR vertical S-correction
adjustment range
I
VSCOR
input current for maximum
S-correction
input current for minimum
S-correction
δVSCOR symmetry error of S-correction maximum ∆VSCOR −−±0.7 %
V
ref(VSCOR)
V
SAWM(p-p)
reference voltage at input − 5.0 − V
voltage amplitude of
superimposed logarithmic
sawtooth (peak-to-peak value)
= 0; note 11 − 60 − %
I
VAMP
= −135 µA; note 11 − 100 − %
I
VAMP
−110 −120 −135 µA
− 0 −µA
note 12 2.25 2.5 2.75
VGA350 − 116.8 − %
VGA400 − 102.2 − %
VGA480 − 100.0 − %
I
= −135 µA; note 11 −−11.5 − %
VPOS
= 0; note 11 − +11.5 − %
I
VPOS
−110 −120 −135 µA
− 0 −µA
0 − 0.1 V
I
I
= 0; note 11 − 2 − %
VSCOR
VSCOR
= −135 µA;
− 46 − %
note 11
−110 −120 −135 µA
− 0 −µA
note 13 −−145 mV
1996 Jul 18 17
Page 18
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
Vertical output stage [VOUT1 (pin 13) and VOUT2 (pin 12)]
∆I
VOUT(nom)
nominal differential output
current (peak-to-peak value)
∆I
VOUT(max)
(∆I
maximum differential output
VOUT
=I
VOUT1
− I
VOUT2
current (peak value)
V
VOUT1
δ
V(offset)
, V
VOUT2
(∆I
allowed voltage at outputs 0 − 4.2 V
maximum offset error of vertical
VOUT
=I
VOUT1
− I
VOUT2
output currents
δ
V(lin)
maximum linearity error of
vertical output currents
EW drive output
DRIVE OUTPUT STAGE [EWDRV (PIN 11)]
EW
V
EWDRV
bottom output voltage
(internally stabilized)
maximum output voltage note 14 7.0 −−V
I
EWDRV
TC
EWDRV
output load current −−±2.0 mA
temperature coefficient of
output signal
ADJUSTMENT OF EW PARABOLA AMPLITUDE (see Figs 3 to 8) [EWPAR (PIN 21)]
V
PAR(EWDRV)
I
EWPAR
parabola amplitude I
input current for maximum
amplitude
input current for minimum
amplitude
V
ref(EWPAR)
reference voltage at input − 5.0 − V
ADJUSTMENT OF HORIZONTAL SIZE (see Figs 3 to 8) [EWWID (PIN 32)]
V
DC(EWDRV)
I
EWWID
EW parabola DC voltage shift I
input current for maximum DC
shift
input current for minimum DC
shift
V
ref(EWWID)
reference voltage at input − 5.0 − V
nominal settings; note 11 0.76 0.85 0.94 mA
)
0.54 0.6 0.66 mA
)
nominal settings; note 11 −−±2.5 %
nominal settings; note 11 −−±1.5 %
V
PAR(EWDRV)
V
DC(EWDRV)
=0;
=0;
1.05 1.2 1.35 V
EWTRP centred
−−600 10−6/K
= 0; note 11 − 0.05 − V
EWPAR
I
EWPAR
= −135 µA;
− 3 − V
note 11
−110 −120 −135 µA
− 0 −µA
EWWID
= −135 µA;
− 0.1 − V
note 11
I
= 0; note 11 − 4.2 − V
EWWID
− 0 −µA
−110 −120 −135 µA
1996 Jul 18 18
Page 19
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
ADJUSTMENT OF TRAPEZIUM CORRECTION (see Figs 3 to 8) [EWTRP (PIN 20)]
V
TRP(EWDRV)
I
EWTRP
trapezium correction voltage I
input current for maximum
positive trapezium correction
input current for maximum
negative trapezium correction
V
ref(EWTRP)
V
off(EWTRP)
reference voltage at input − 5.0 − V
trapezium correction is centred
if EWTRP (pin 20) is forced to
ground
V
PARM(p-p)
amplitude of superimposed
logarithmic parabola
(peak-to-peak value)
TRACKING OF EWDRV OUTPUT SIGNAL WITH f
f
H(MULTI)
V
PAR(EWDRV)
fH range for tracking 24 − 80 kHz
parabola amplitude at EWDRV
(pin 11)
δV
EWDRV
V
EWWID
linearity error of fHtracking −−8%
voltage range to inhibit tracking 0 − 0.1 V
Focus section [FOCUS (pin 10)]
I
FOCUS(p-p)
amplitude of horizontal
parabola (peak-to-peak value)
V
FOCUS(min)
input voltage for minimum
horizontal parabola amplitude
V
FOCUS(max)
input voltage for maximum
horizontal parabola amplitude
I
note 11
note 15 −−145 mV
PROPORTIONAL VOLTAGE
H
I
fH= 31.45 kHz; note 16
I
fH= 70 kHz; note 16
function disabled; note 16 2.7 3.0 3.3 V
V
V
= 0; note 11 −−0.5 − V
EWTRP
EWTRP
= −135 µA;
− +0.5 − V
−110 −120 −135 µA
− 0 −µA
0 − 0.1 V
= 1.052 mA;
HREF
= 2.341 mA;
HREF
FOCUS
FOCUS
=1V − 0.03 − mA
=4V − 1 − mA
1.3 1.45 1.6 V
2.7 3.0 3.3 V
0.9 1.0 1.1 V
3.65 4.0 4.4 V
1996 Jul 18 19
Page 20
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
B+ control section (see Figs 12 and 13)
TRANSCONDUCTANCE AMPLIFIER [BIN (PIN 5) AND BOP (PIN 3)]
V
BIN
I
BIN(max)
V
ref(int)
V
BOP(min)
V
BOP(max)
I
BOP(max)
g transconductance of OTA note 17 30 50 70 mS
G
open
C
BOP
VOLTAGE COMPARATOR [BSENS (PIN 4)]
V
BSENS
V
BOP
I
BSENS
OPEN COLLECTOR OUTPUT STAGE [BDRV (PIN 6)]
I
BDRV(max)
I
leakage(BDRV)
V
sat(BDRV)
t
off(min)
t
d(BDRV)
BSENS DISCHARGE CIRCUIT
V
STOP(BSENS)
I
DISC(BSENS)
V
RESTART(BSENS)
C
BSENS
input voltage 0 − 5.25 V
maximum input current −−±1µA
reference voltage at internal
2.37 2.5 2.58 V
non-inverting input of OTA
minimum output voltage − 0.4 − V
maximum output voltage I
< 1 mA 5 5.3 5.6 V
BOP
maximum output current −±500 −µA
open-loop gain note 18 − 86 − dB
minimum value of capacitor at
4.7 −−nF
BOP (pin 3)
voltage range of positive
0 − 5V
comparator input
voltage range of negative
0 − 5V
comparator input
maximum leakage current discharge disabled −−−2µA
maximum output current 20 −−mA
output leakage current V
saturation voltage I
=16V −−3µA
BDRV
< 20 mA −−300 mV
BDRV
minimum off-time − 250 − ns
delay between BDRV pulse
and HDRV pulse
discharge stop level capacitive load;
discharge current V
measured at
V
HDRV,VBDRV
I
= 0.5 mA
BSENS
> 2.5 V 4.5 6 7.5 mA
BSENS
− 500 − ns
=3V
0.85 1.0 1.15 V
threshold voltage for restart fault condition 1.2 1.3 1.4 V
minimum value of capacitor at
2 −−nF
BSENS (pin 4)
Internal reference, supply voltage and protection
V
STAB(VCC)
external supply voltage for
complete stabilization of all
internal references
I
VCC
PSRR power supply rejection ratio of
supply current − 49 − mA
f = 1 kHz 50 −−dB
internal supply voltage
1996 Jul 18 20
9.2 − 16 V
Page 21
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
Notes to the characteristics
1. For duration of vertical blanking pulse see characteristics of “Vertical oscillator (oscillator frequency in application
without adjustment of free-running frequency fv(o))”.
2. Continuous blanking at CLBL (pin 16) will be activated, if one of the following conditions is true:
a) No horizontal flyback pulses at HFLB (pin 1) within a line
b) X-ray protection is triggered
c) Voltage at HPLL2 (pin 31) is low (for soft start of horizontal drive)
d) Supply voltage at VCC (pin 9) is low
e) PLL1 unlocked while frequency-locked loop is in search mode.
3. To ensure safe locking of the horizontal oscillator, one of the following procedures is required:
a) Search mode starts always from f
ground in parallel with an 8.2 kΩ resistor in series with a 47 nF capacitor.
b) Search mode starts either from f
components are a 1.5 nF capacitor from pin 26 to ground in parallel with a 27 kΩ resistor in series with a 47 nF
capacitor.
c) After locking is achieved, HPOS can be operated in the normal way.
4. Loading of HPLL1 (pin 26) is not allowed.
5. Oscillator frequency is f
when no sync input signal is present (no continuous blanking at pin 16).
min
6. Voltage at HPLL1 (pin 26) is fed to HBUF (pin 27) via a buffer. Disturbances caused by horizontal sync are removed
by an internal sample-and-hold circuit.
. Then the PLL1 filter components are a 3.3 nF capacitor from pin 26 to
min
or f
min
with HPOS in middle position (I
max
=60µA). Then the PLL1 filter
HPOS
7. Input resistance at HPOS (pin 30):
R
HPOS
kT
------
8. Full vertical sync range with constant amplitude (f
1
×=
---------------
q
I
HPOS
V(min):fV(max)
= 1 : 2.5) can be made usable by choosing an
application with adjustment of free-running frequency.
9. If higher vertical frequencies are required, sync range can be shifted by using a smaller capacitor at VCAP (pin 24).
10. Value of resistor at VREF (pin 23) may not be changed.
11. All vertical and EW adjustments are specified at nominal vertical settings, which means:
a) ∆VAMP = 100% (I
VAMP
= 135 µA)
b) ∆VSCOR = 0 (pin 19 open-circuit)
c) ∆VPOS centred (pin 17 forced to ground)
d) VGA presets disabled (current ratio I
HBUF:IHREF
< 2.25)
e) fH= 70 kHz.
12. VGA presets are enabled below the horizontal frequency at which the current ratio I
HBUF:IHREF
exceeds the
specified value.
13. The superimposed logarithmic sawtooth at VSCOR (pin 19) tracks with internal VGA settings and with VPOS, but
not with VAMP settings. The superimposed waveform is described by with ‘d’ being the modulation
5
depth of a sawtooth from −
⁄6to +5⁄6. A linear sawtooth with the same modulation depth can be recovered in an
kT
------ -
1d–
In×
------------ 1d+
q
external long-tailed pair (see Fig.17).
14. The output signal at EWDRV (pin 11) may consist of parabola + DC shift + trapezium correction. These adjustments
have to be carried out in a correct relationship to each other in order to avoid clipping due to the limited output voltage
range at EWDRV.
1996 Jul 18 21
Page 22
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
15. The superimposed logarithmic parabola at EWTRP (pin 20) tracks with internal VGA settings and with VPOS, but
not with VAMP settings (see Fig.17).
16. If fH tracking is enabled, the amplitude of the complete EWDRV output signal (parabola + DC shift + trapezium) will
be changed proportional to I
17. First pole of transconductance amplifier is 5 MHz without external capacitor (will become the second pole, if the OTA
operates as an integrator).
V
18. Open-loop gain is at f= 0 with no resistive load and C
BOP
------------- V
BIN
Vertical and EW adjustments
. The EWDRV low level of 1.2 V remains fixed.
HREF
= 4.7 nF (from BOP (pin 3) to GND).
BOP
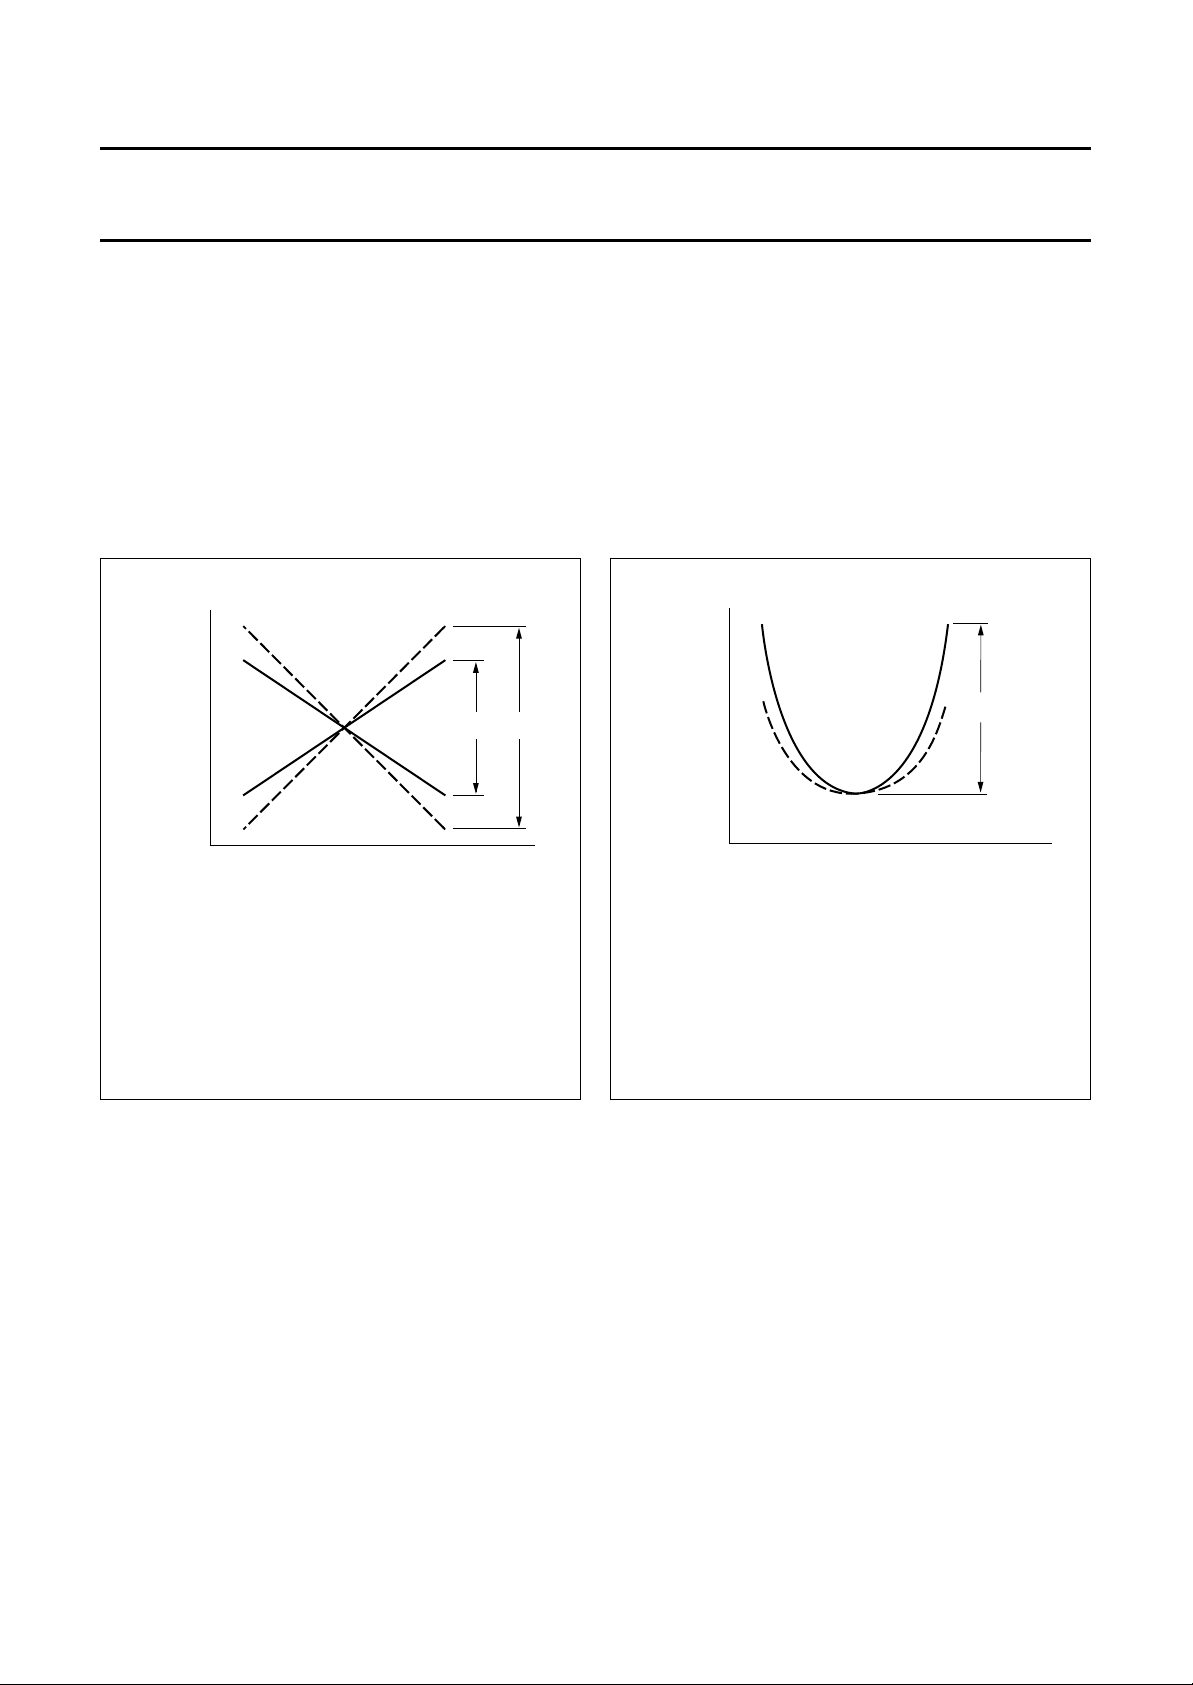
handbook, halfpage
I
VOUT1
I
VOUT2
(1) ∆I1 is the maximum amplitude setting at VAMP (pin 18);
VGA presets disabled, VPOS centred and VSCOR = 0%.
I∆
2
VAMP∆
Fig.3 I
------- I∆
1
VOUT1
100%×=
and I
as functions of time.
VOUT2
∆l
2
MBG590
∆l
1
t
handbook, halfpage
V
EWDRV
(1)
∆EWPAR = 0 to V
Fig.4 V
PAR(EWDRV)
.
as a function of time.
EWDRV
MBG591
V
PAR(EWDRV)
t
1996 Jul 18 22
Page 23
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
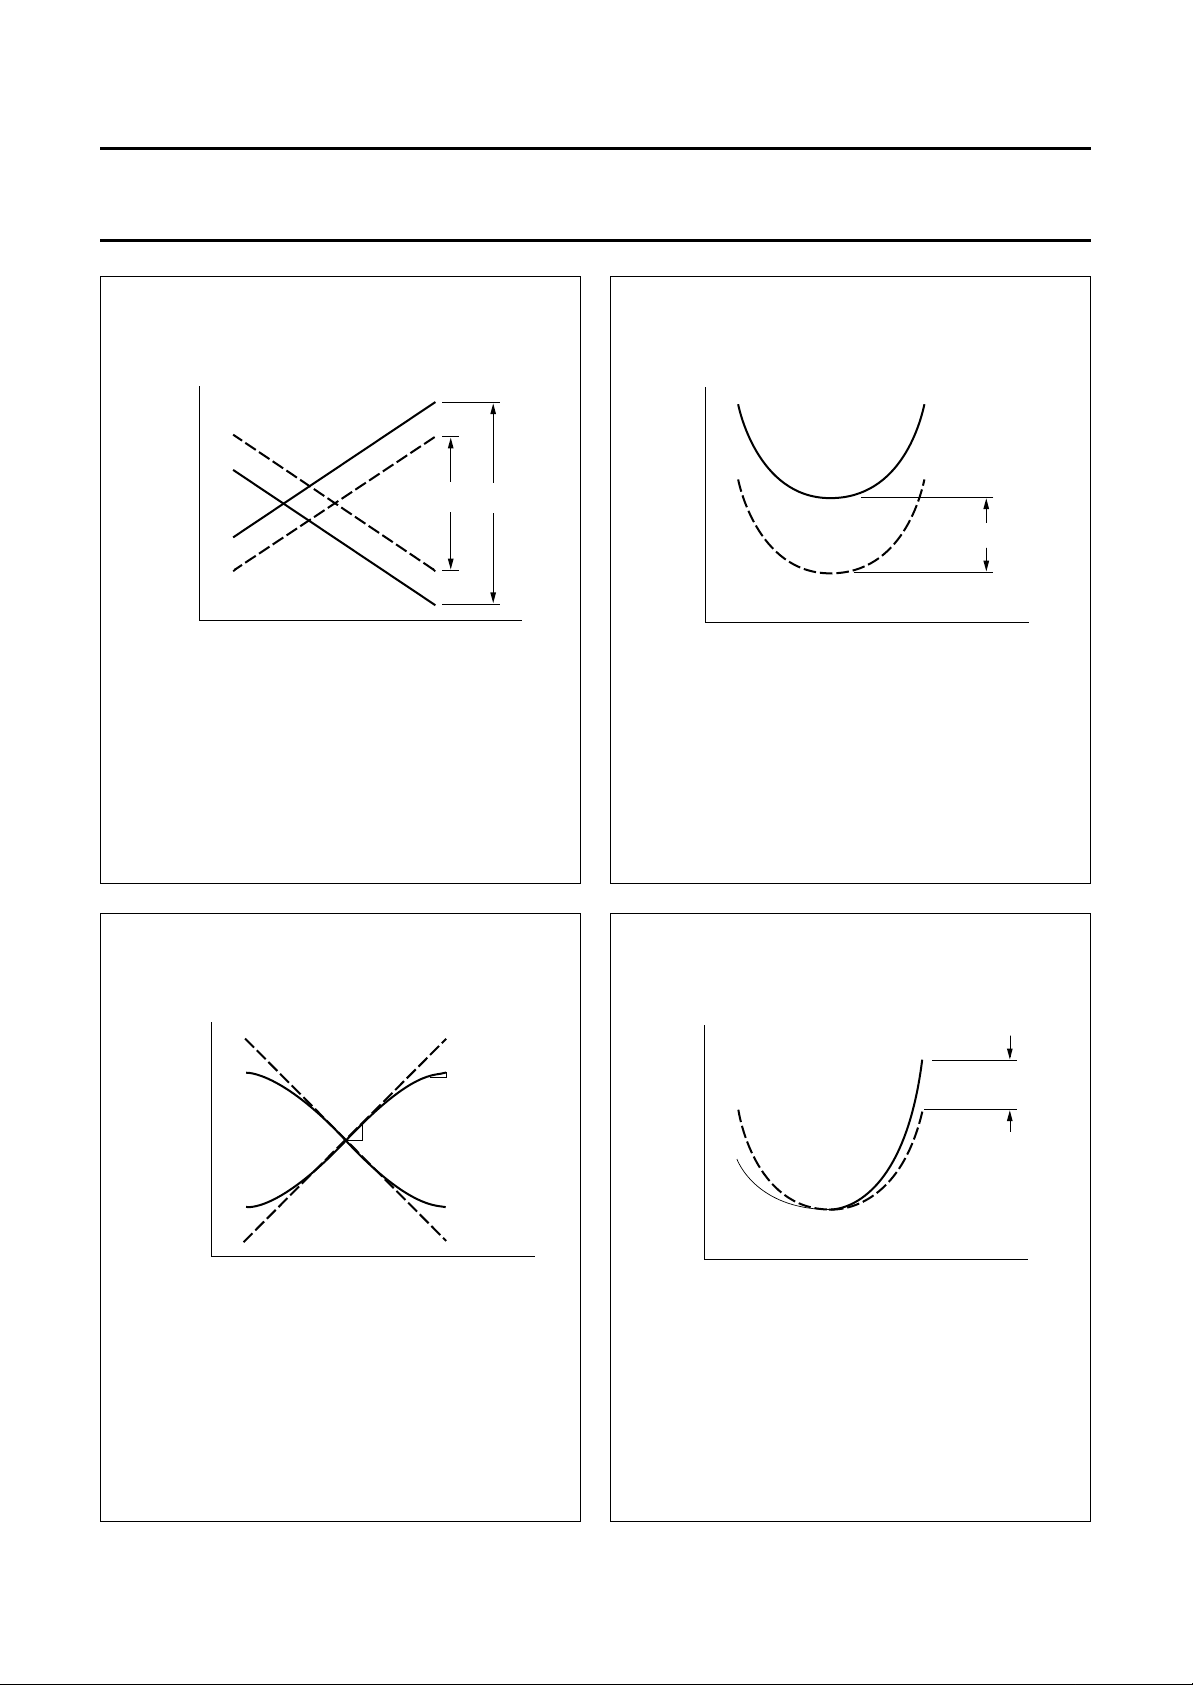
handbook, halfpage
I
VOUT1
I
VOUT2
(1)
∆l
∆l
1
(1) ∆I1 is VPOS adjustment centred; maximum amplitude setting at
VAMP (pin 18) and VGA presets disabled.
∆ I1∆–
I
VPOS∆
Fig.5 I
2
--------------------- -
∆×
2I
VOUT1
1
and I
100%×=
as functions of time.
VOUT2
2
t
MBG592
handbook, halfpage
V
EWDRV
∆EWWID = 0 to V
Fig.6 V
DC(EWDRV)
EWDRV
V
DC(EWDRV)
.
as a function of time.
MBG593
t
handbook, halfpage
I
VOUT1
I
VOUT2
(1)
/∆t
∆l
1
(1) ∆I1 is VSCOR = 0%; maximum amplitude setting at VAMP
(pin 18) and VGA presets disabled.
–
I∆
VSCOR∆
Fig.7 I
1I∆2
--------------------- I
∆
VOUT1
1
and I
100%×=
as functions of time.
VOUT2
MBG594
∆l2/∆t
t
1996 Jul 18 23
handbook, halfpage
V
EWDRV
∆EWTRP = ±V
Fig.8 V
TRP(EWDRV)
EWDRV
.
as a function of time.
MBG595
V
TRP(EWDRV)
t
Page 24
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
Pulse diagrams
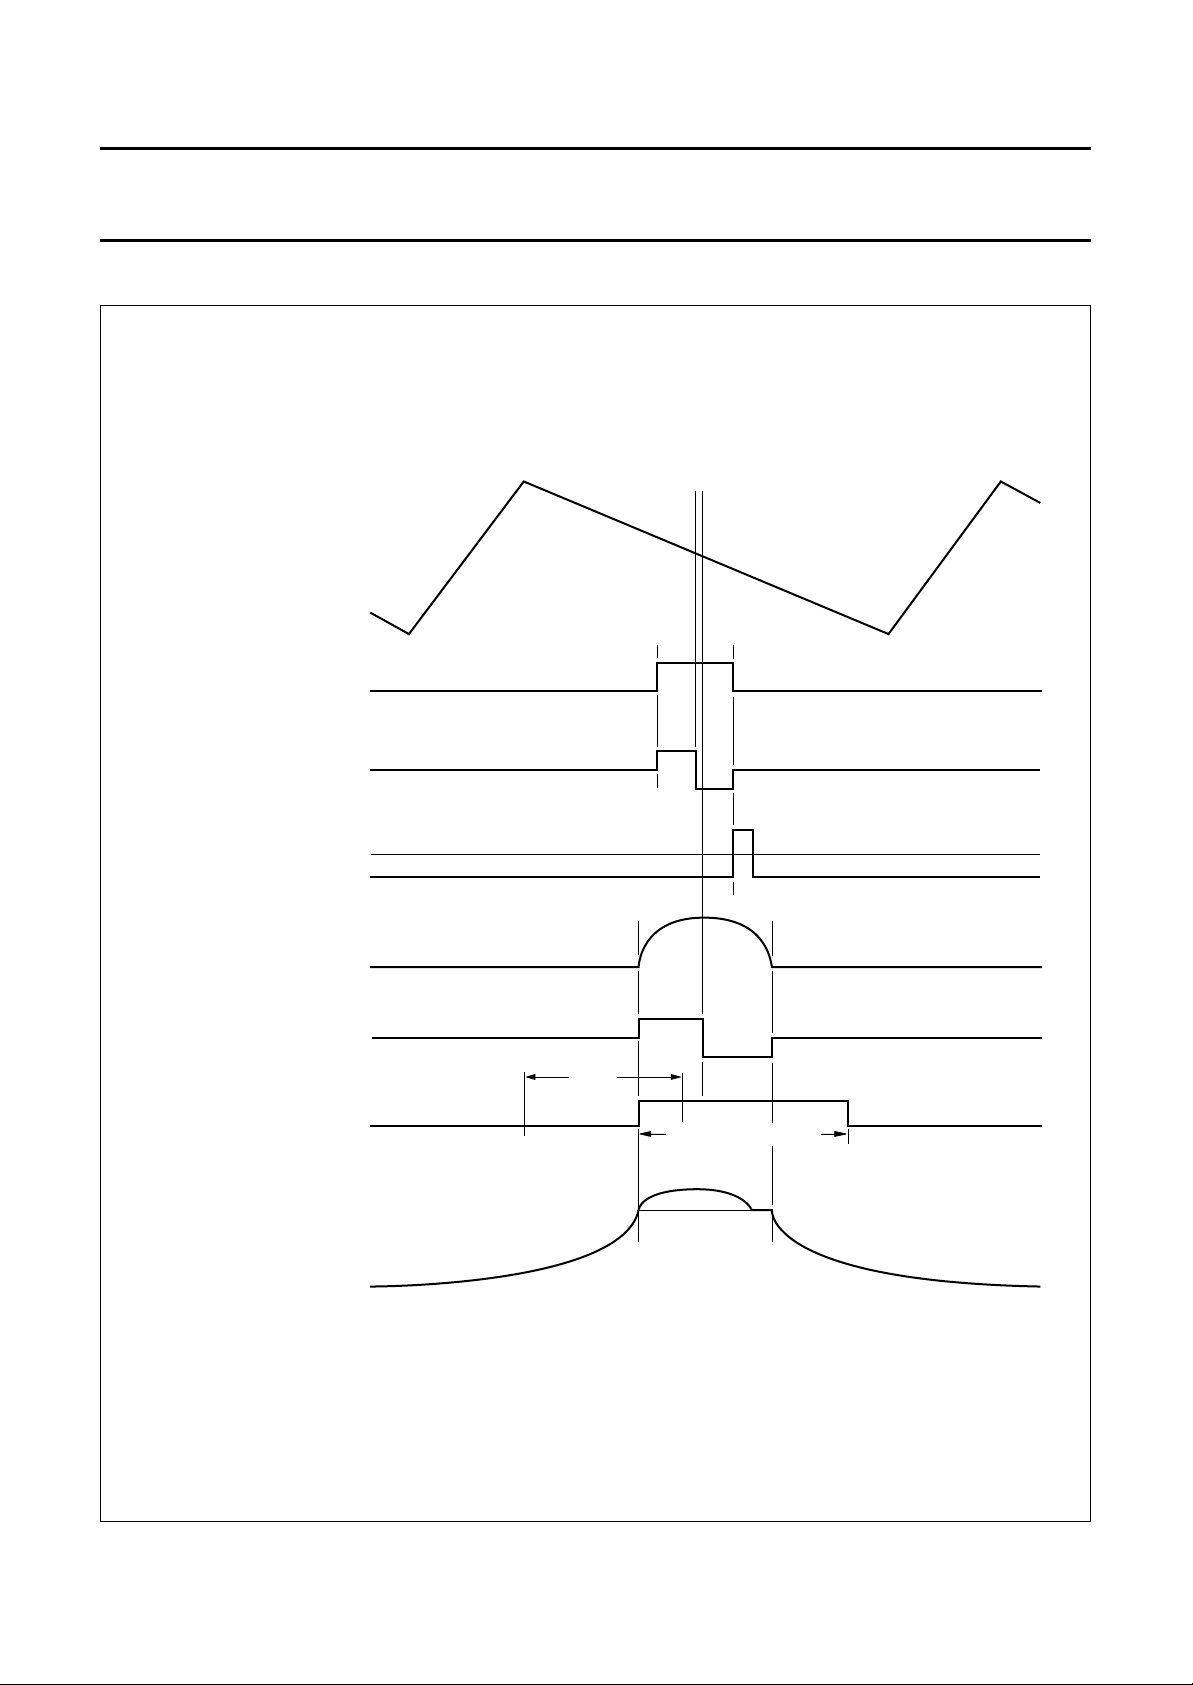
handbook, full pagewidth
horizontal oscillator sawtooth
at HCAP (pin 29)
horizontal sync pulse
PLL1 control current
at HPLL1 (pin 26)
video clamping pulse
at CLBL (pin 16)
triggered on
trailing edge of horizontal sync
line flyback pulse
at HFLB (pin 1)
PLL2 control current
at HPLL2 (pin 31)
line drive pulse at HDRV (pin 7)
PLL2
control range
-
+
+
45 to 48% of line period
–
vertical blanking level
horizontal focus parabola
at FOCUS (pin 10)
Fig.9 Pulse diagram for horizontal part.
1996 Jul 18 24
MBG598
Page 25
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
4.0 V
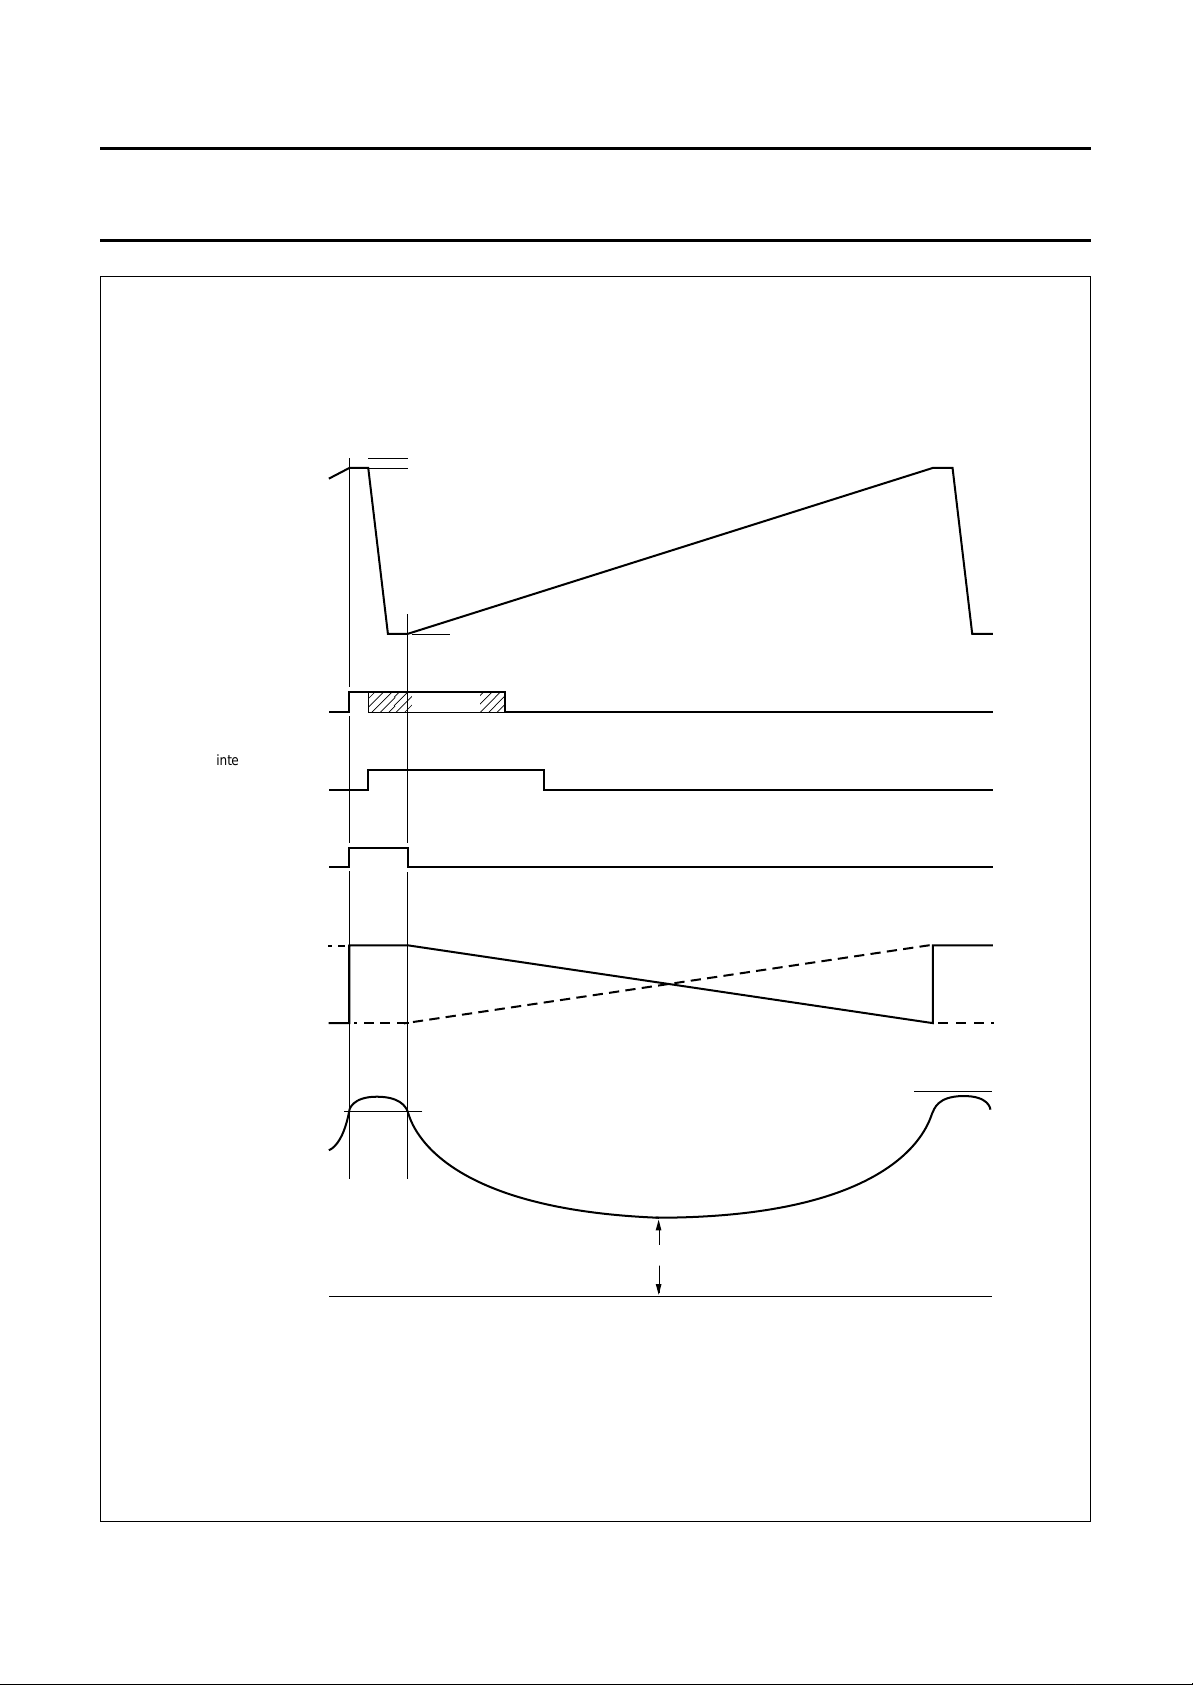
handbook, full pagewidth
vertical oscillator sawtooth
at VCAP (pin 24)
automatic trigger level
synchronized trigger level
3.8 V
1.4 V
vertical sync pulse
internal trigger
inhibit window
(typical 6.7 ms)
vertical blanking pulse
at CLBL (pin 16)
differential output currents
VOUT1 (pin 13) and
VOUT2 (pin 12)
EW drive waveform
at EWDRV (pin 11)
inhibited
tip-parabola
I
VOUT1
I
VOUT2
EW parabola 3 V (p-p) maximum
DC shift 4 V maximum
7.0 V maximum
LOW level 1.2 V fixed
MBG597
Fig.10 Pulse diagram for vertical part.
1996 Jul 18 25
Page 26
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
handbook, full pagewidth
handbook, full pagewidth
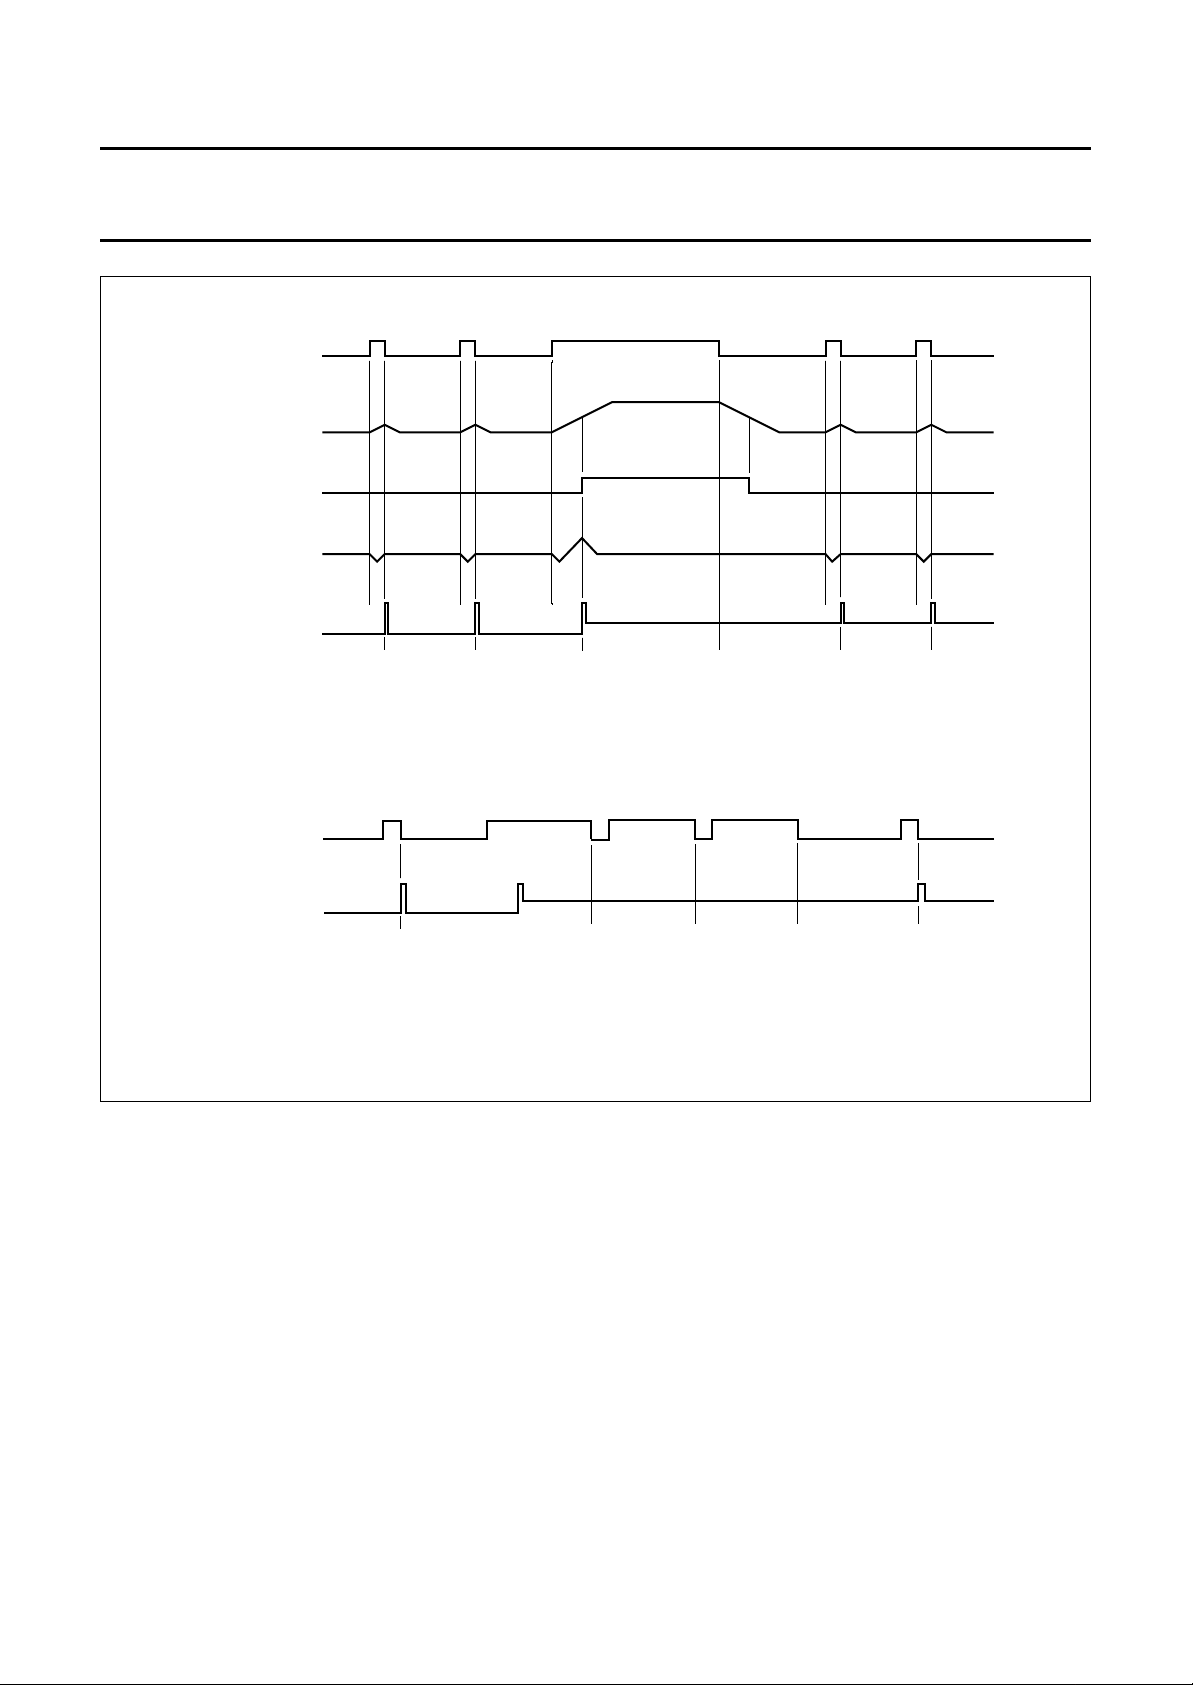
composite sync (TTL)
at HSYNC (pin 15)
internal integration of
composite sync
internal vertical
PLL1 control voltage
at HPLL1 (pin 26)
clamping and blanking
pulses at CLBL (pin 16)
composite sync (TTL)
at HSYNC (pin 15)
clamping and blanking
pulses at CLBL (pin 16)
trigger pulse
MGC947
a. Reduced influence of vertical sync on horizontal phase.
MBG596
b. Generation of video clamping pulses during vertical sync with serration pulses.
Fig.11 Pulse diagrams for composite sync applications.
1996 Jul 18 26
Page 27
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
APPLICATION INFORMATION
handbook, full pagewidth
1
horizontal
flyback pulse
EWDRV
C1
D1
R1
R3
2.5 V
5
V
BIN
R2
OTA
C2
2
V
HDRV
34
V
BOP
4
V
BSENS
C
BOP
>4.7 nF
7
SRQ
Q
DISCHARGE
V
CC
6
INVERTING
R6
BUFFER
V
V
3
BDRV
R5
C4 R4
i
L
TR1
D2
HORIZONTAL
OUTPUT
STAGE
MBG599
For f < 50 kHz and C2 < 47 nF calculation formulas and behaviour of the OTA are the same as for an OP. An exception is the limited output current at
BOP (pin 3). See Chapter “Characteristics”, Row Head “B+ control section (see Figs 12 and 13)”.
a. Feedback mode application.
handbook, full pagewidth
1
horizontal
flyback pulse
2
V
3
V
V
BSENS
4
V
HDRV
BDRV
BSENS
= V
BOP
t
on
t
d(BDRV)
t
off(min)
MBG600
V
RESTART(BSENS)
V
STOP(BSENS)
b. Waveforms for normal operation. c. Waveforms for fault condition.
Fig.12 Application and timing for feedback mode.
1996 Jul 18 27
Page 28
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
handbook, full pagewidth
EHT adjustment
2.5 V
R1 R2
V
BIN
power-down
5
TR2
OTA
2
V
HDRV
34
V
BOPVBSENS
D1
C1
> 4.7 nF
C
BOP
4
C
BSENS
>2 nF
7
DISCHARGE
R3
SRQ
V
CC
R4
6
INVERTING
BUFFER
Q
V
3
BDRV
HORIZONTAL
OUTPUT
STAGE
EHT
transformer
TR1
horizontal
flyback pulse
1
D2
I
5
MOSFET
MBG601
handbook, full pagewidth
1
horizontal
flyback pulse
2
V
HDRV
3
V
BDRV
4
V
BSENS
5
I
MOSFET
b. Waveforms for normal operation. c. Waveforms for fault condition.
V
BOP
t
on
t
d(BDRV)
a. Forward mode application.
t
(discharge time of C
V
BOP
off
Fig.13 Application and timing for feed forward mode.
BSENS
)
V
RESTART(BSENS)
V
STOP(BSENS)
MBG602
1996 Jul 18 28
Page 29
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
Start-up and shut-down sequence
handbook, full pagewidth
V
CC
(1) See Fig.15 for PLL2 soft-start.
continuous blanking off
8.5 V
PLL2 enabled
frequency detector enabled
8.2 V video clamping pulse enabled
BDRV enabled
VOUT1 and VOUT2 enabled
5.8 V PLL2 soft start sequence begins
4.0 V continuous blanking CLBL (pin 16) activated
(1)
a. Start-up sequence.
V
CC
V
HPLL2
> 8.2 V
and
> 3.7 V
V
CC
V
HPLL2
MBG555
> 8.5 V
and
time
> 4.4 V
handbook, full pagewidth
V
CC
continuous blanking CLBL (pin 16) activated
8.5 V
PLL2 disabled
frequency detector disabled
8.0 V
video clamping pulse disabled
BDRV floating
VOUT1 and VOUT2 floating
5.6 V
HDRV floating
4.0 V continuous blanking disappears
time
MBG554
b. Shut-down sequence.
Fig.14 Start-up sequence and shut-down sequence.
1996 Jul 18 29
Page 30
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
PLL2 soft start sequence
handbook, full pagewidth
handbook, full pagewidth
V
HPLL2
3.7 V
duty factor increases
0.5 V
HDRV duty factor begins to increase
a. PLL2 start-up sequence.
MBG553
continuous blanking off
4.4 V
PLL2 enabled
frequency detector enabled
HDRV duty factor has reached nominal value
BDRV enabled
VOUT1 and VOUT2 enabled
time
MBG552
V
HPLL2
continuous blanking CLBL (pin 16) activated
4.4 V
PLL2 disabled
frequency detector disabled
duty factor decreases
b. PLL2 shut-down sequence.
Fig.15 PLL2 soft start sequence.
1996 Jul 18 30
3.7 V
HDRV duty factor begins to decrease
BDRV floating
VOUT1 and VOUT2 floating
0.5 V
HDRV floating
time
Page 31
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
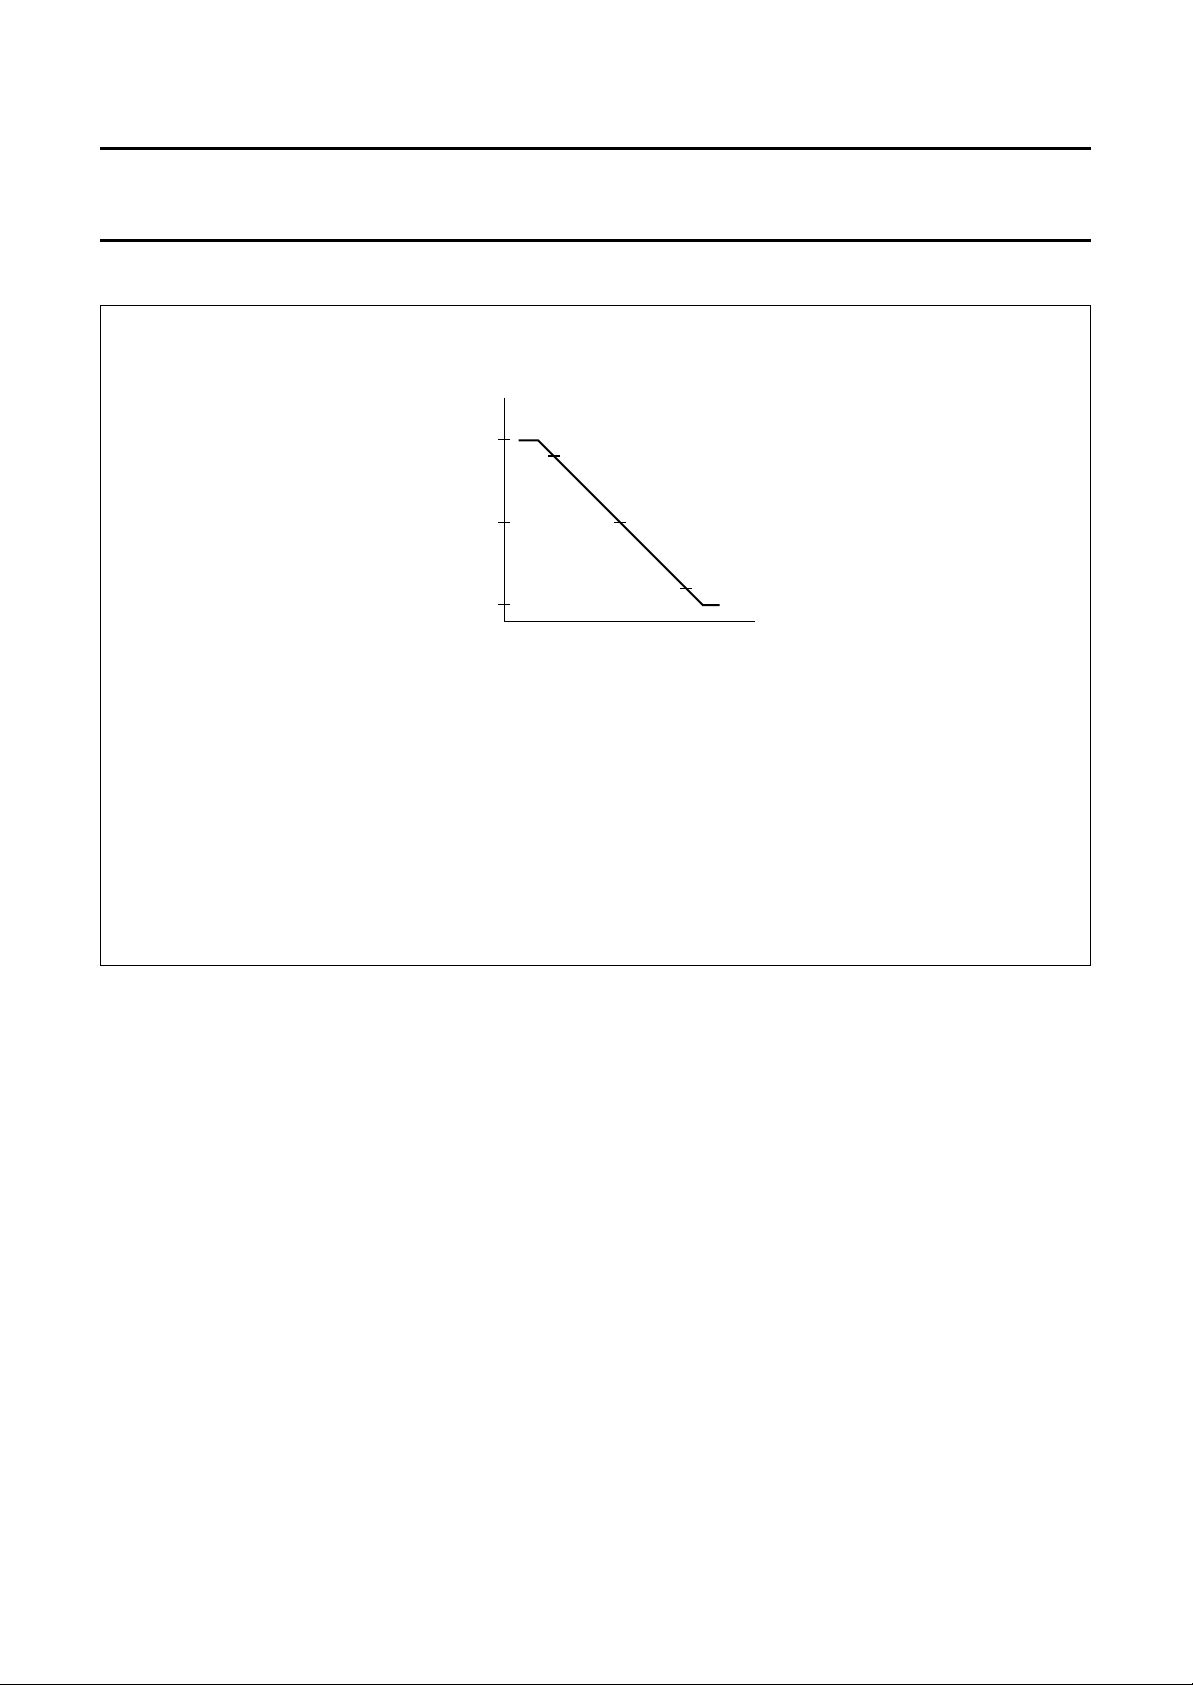
Vertical linearity error
(1) I
VOUT=IVOUT1
(2) I1=I
VOUT
(3) I2=I
VOUT
(4) I3=I
VOUT
Which means:
at V
at V
at V
I
− I
VCAP
VCAP
VCAP
I1I3–
=
--------------
0
Vertical linearity error =
.
VOUT2
= 1.9 V.
= 2.6 V.
= 3.3 V.
2
1max
–
handbook, halfpage
I
VOUT
(1)
(µA)
+415
0
−415
I
–
–
I
1I2
I
0
2I3
or
-------------I
0
--------------
Fig.16 Definition of vertical linearity error.
MBG551
(2)
I
1
(3)
I
2
(4)
I
3
V
VCAP
1996 Jul 18 31
Page 32
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
Usage of superimposed waveforms
handbook, halfpage
120 mV (p-p)
EWPAR
VSCOR
5 V
EWWID
a. VSCOR (pin 19).
VPOS
VAMP
17, 18, 21, 3219
5 V DC
MBG556
handbook, halfpage
EWTRP
5 V
120 mV (p-p)
b. EWTRP (pin 20).
Fig.17 Superimposed waveforms at pins 19 and 20 with pins 17, 18, 21 or 32.
VPOS
VAMP
EWPAR
EWWID
17, 18, 21, 3220
5 V DC
MBG557
1996 Jul 18 32
Page 33
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
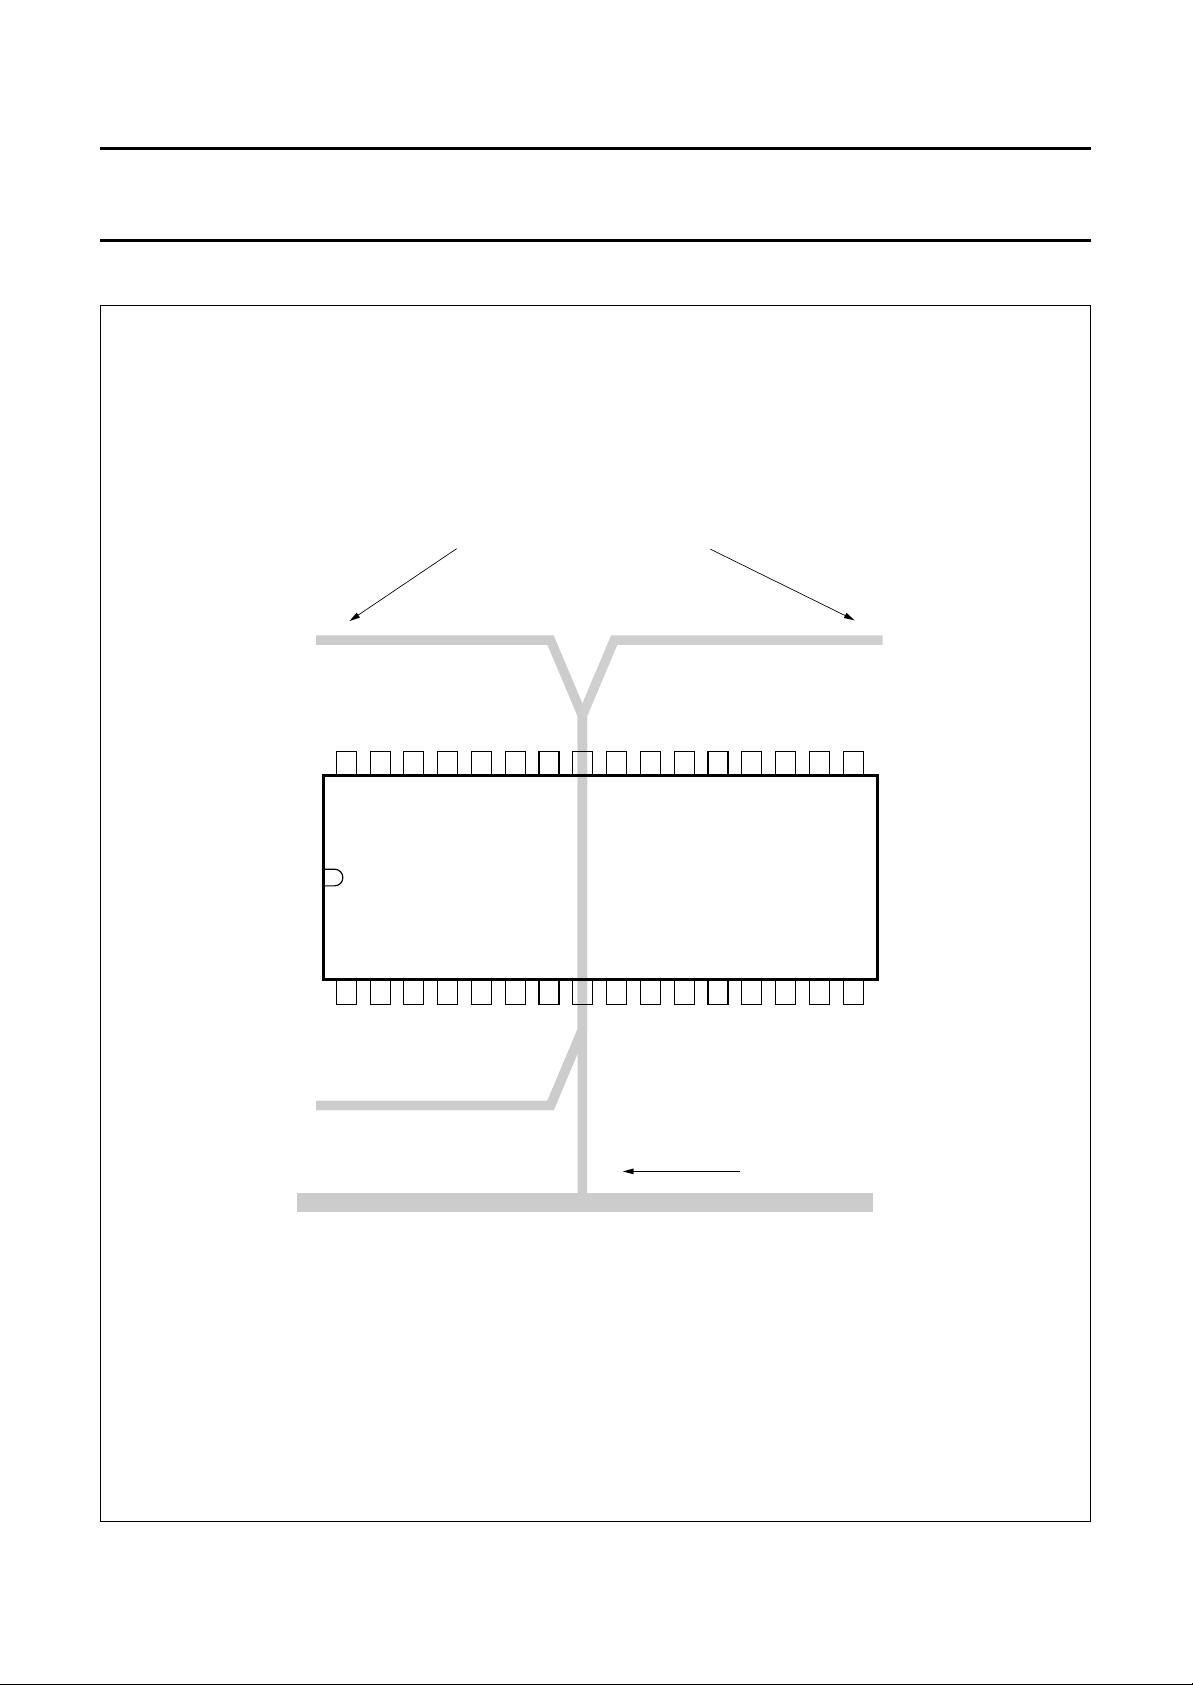
Printed printed-circuit board layout
handbook, full pagewidth
further connections to other components
external components of
horizontal section
32
31
30
29
TDA4855
1
2
3
4
external components of
driver stages
or ground paths are not allowed
external components of
vertical section
28
27
26
25
24
23
5
6
7
8
9
10
22
21
20
19
18
17
11
12
13
14
15
16
only this path may be connected
to ground on PCB
MBG558
For optimum performance of the TDA4855 the ground paths must be routed as shown. Only one connection to other grounds on the PCB is allowed.
Fig.18 Hints for printed-circuit board (PCB) layout.
1996 Jul 18 33
Page 34
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
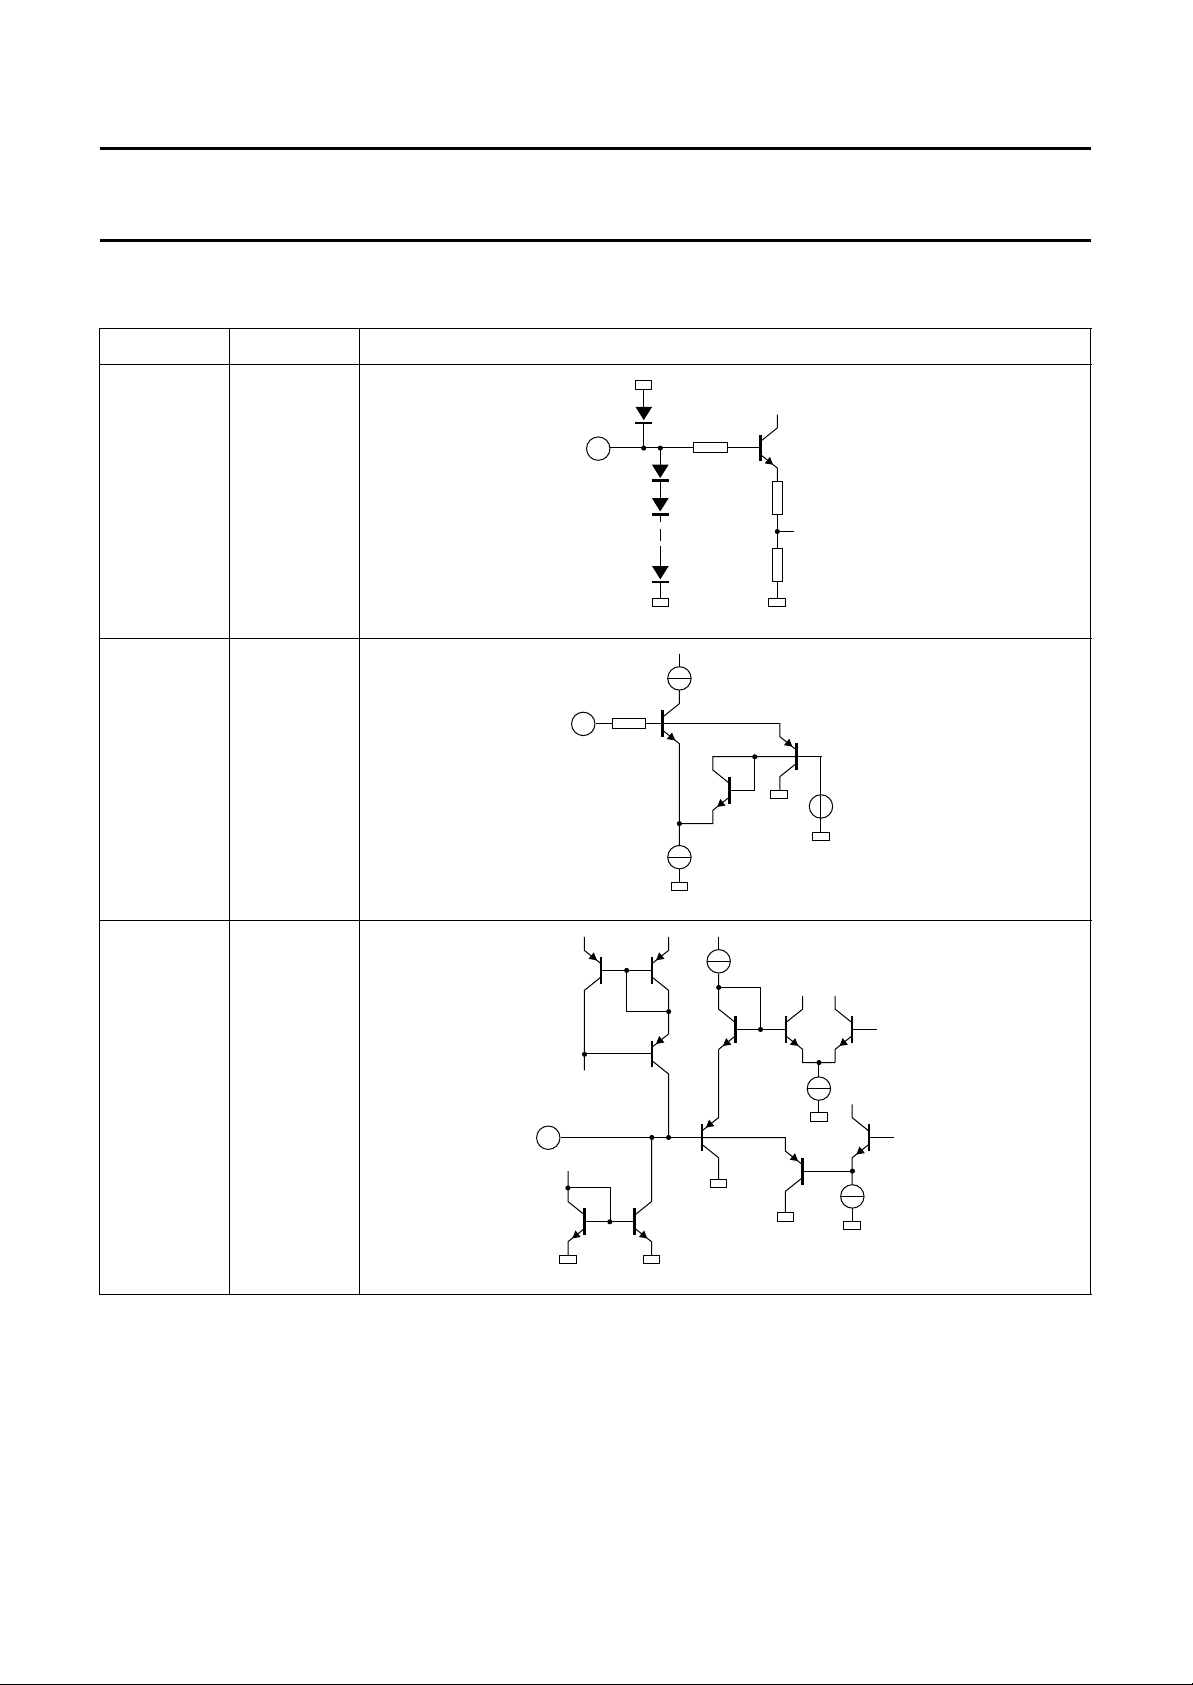
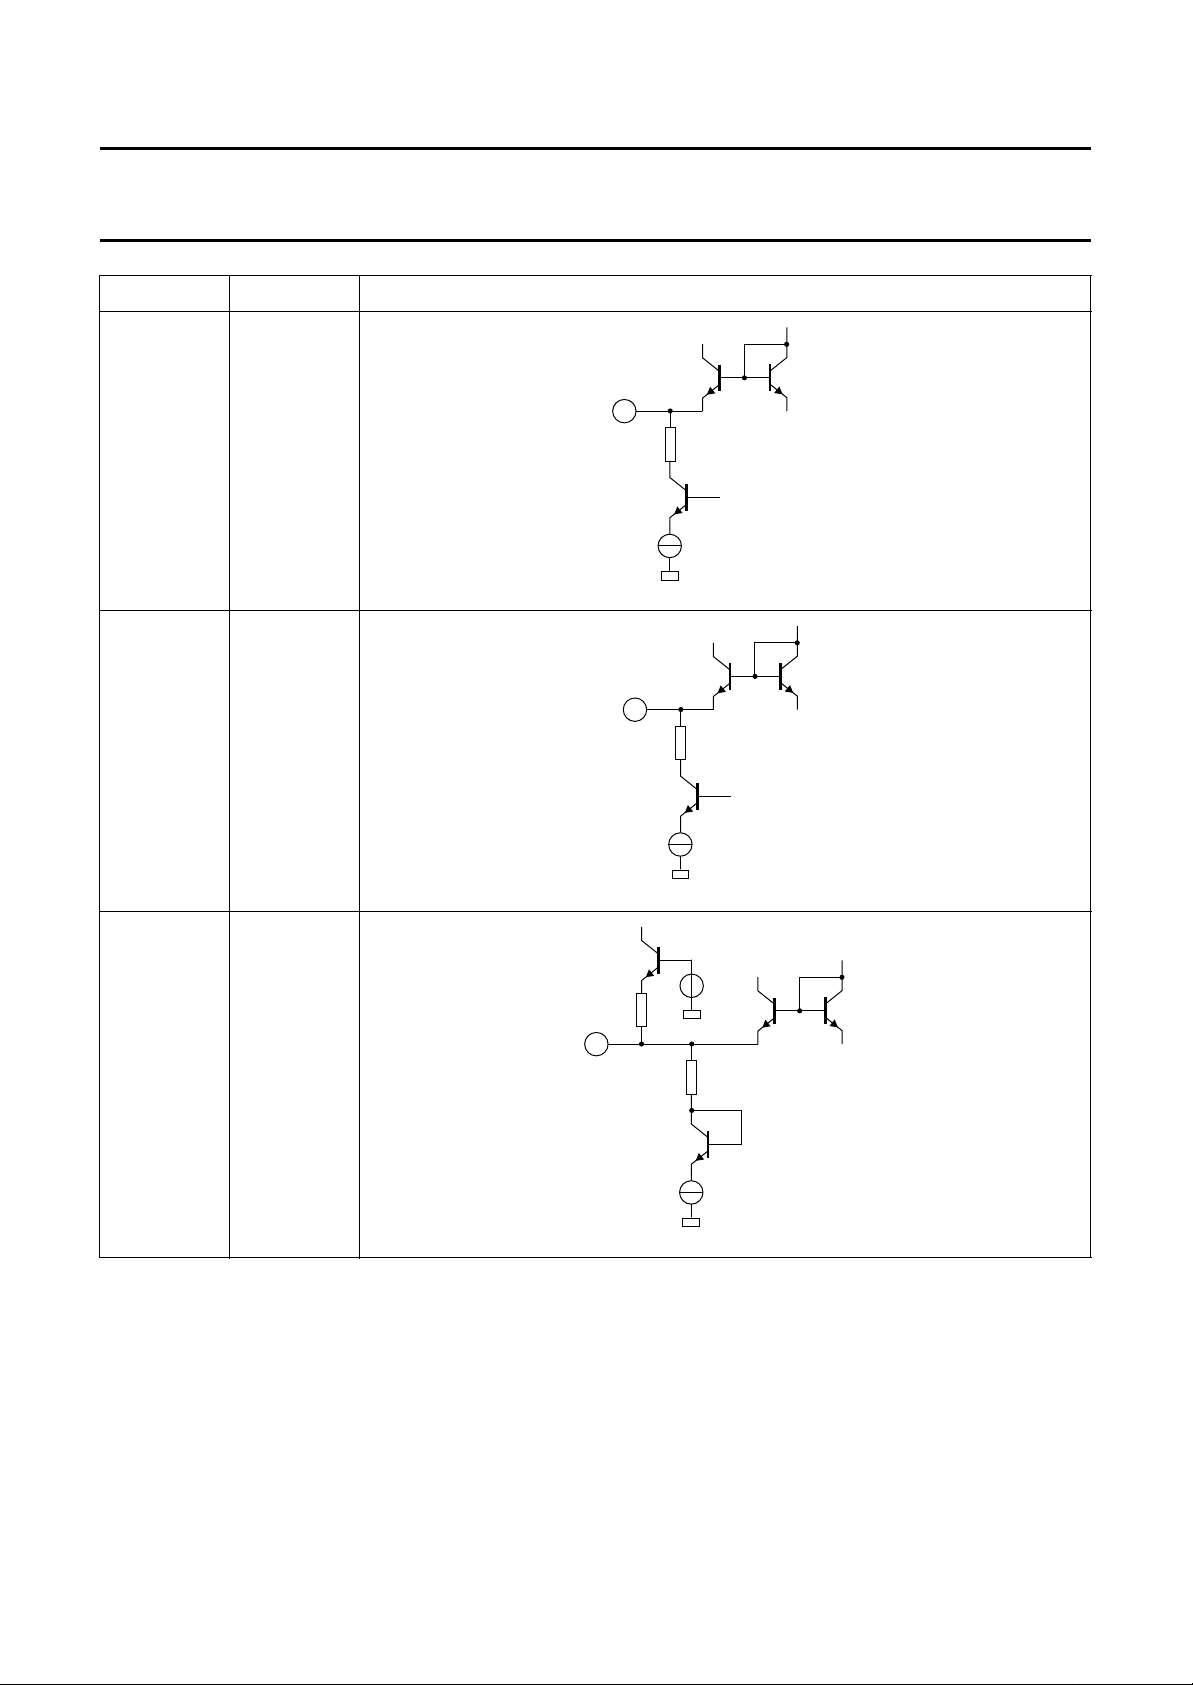
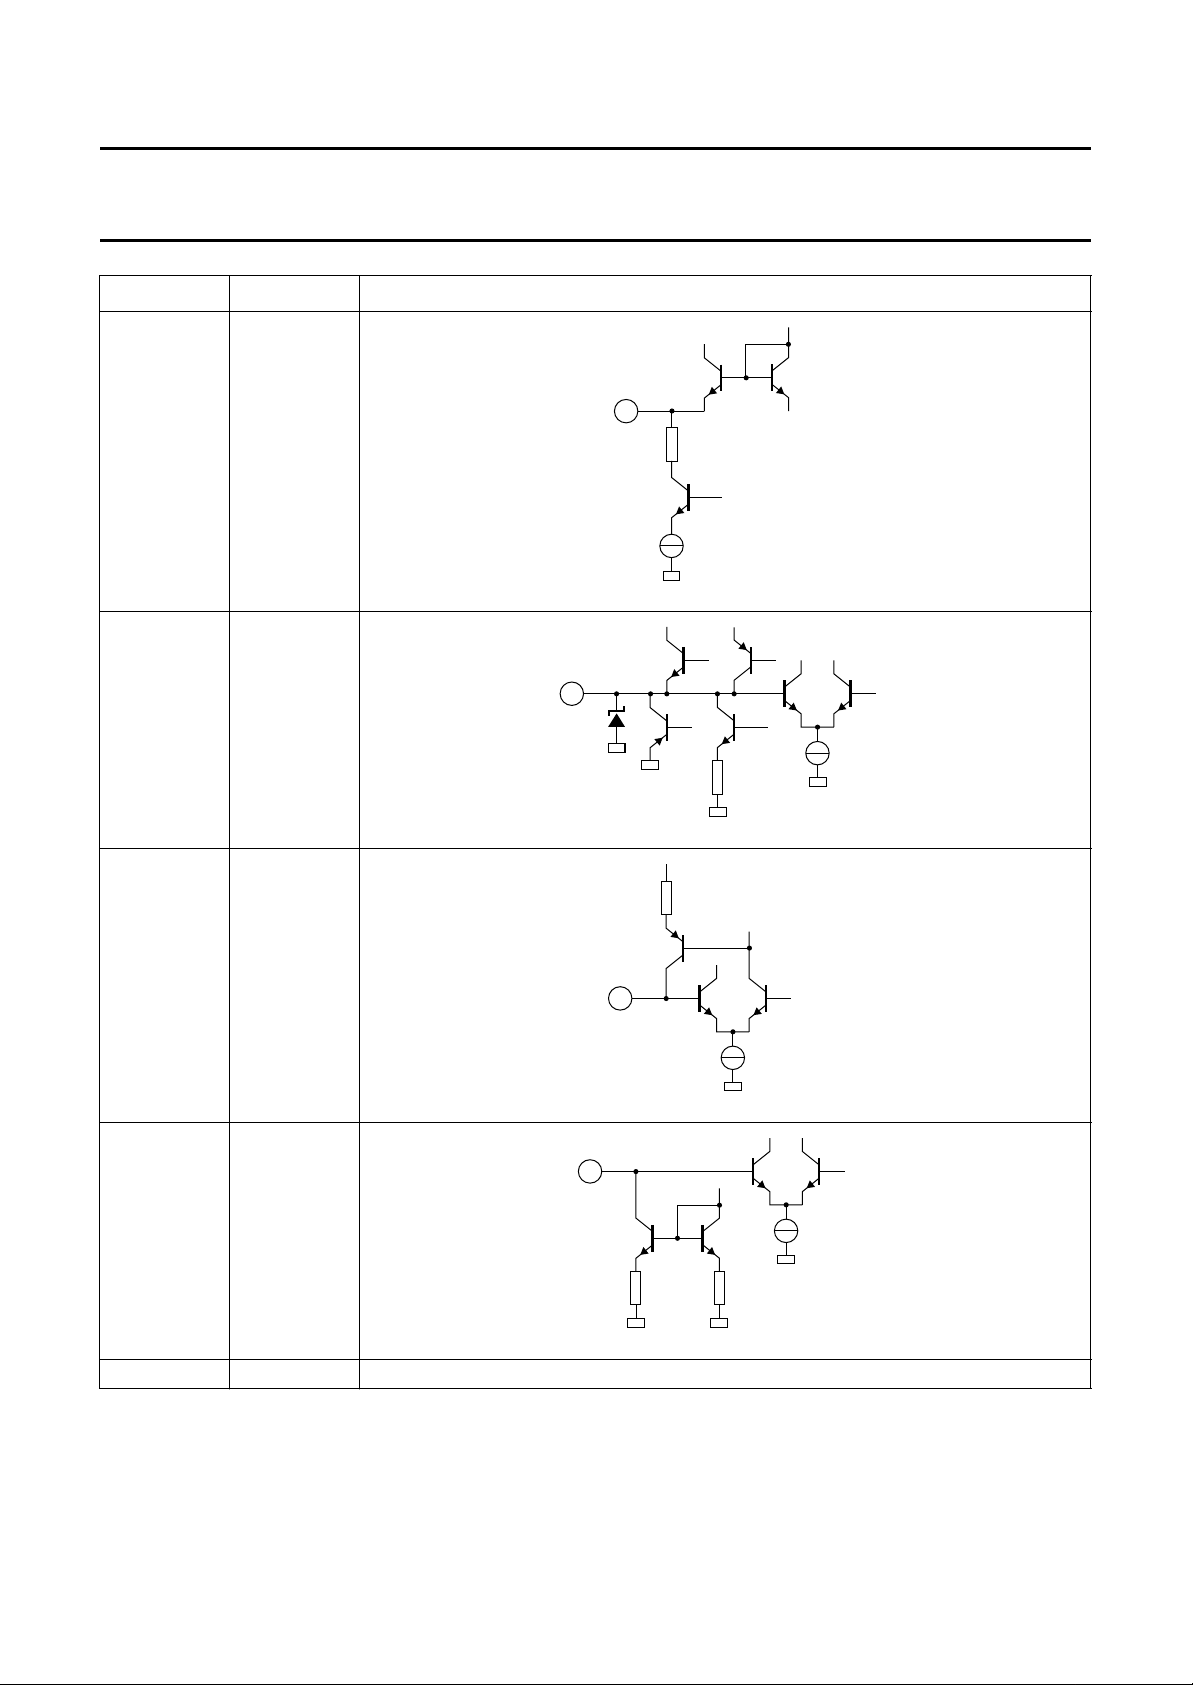
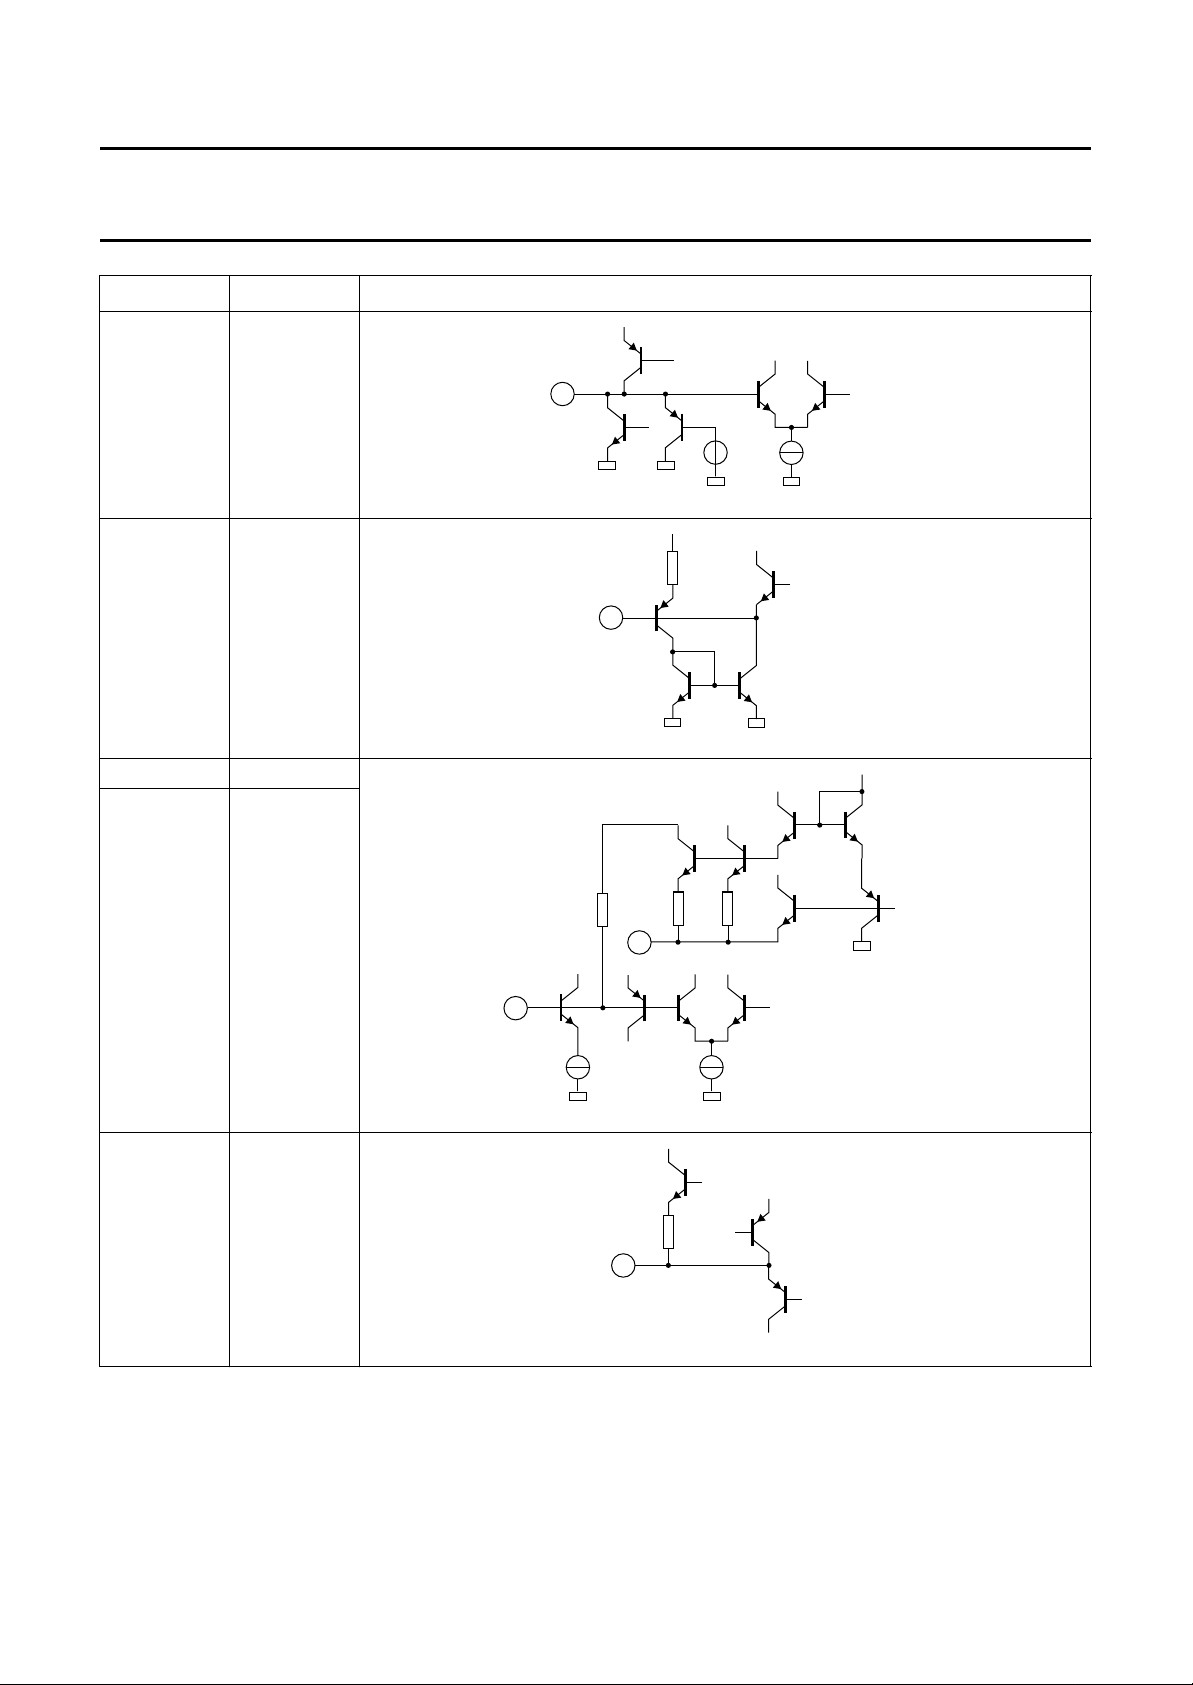
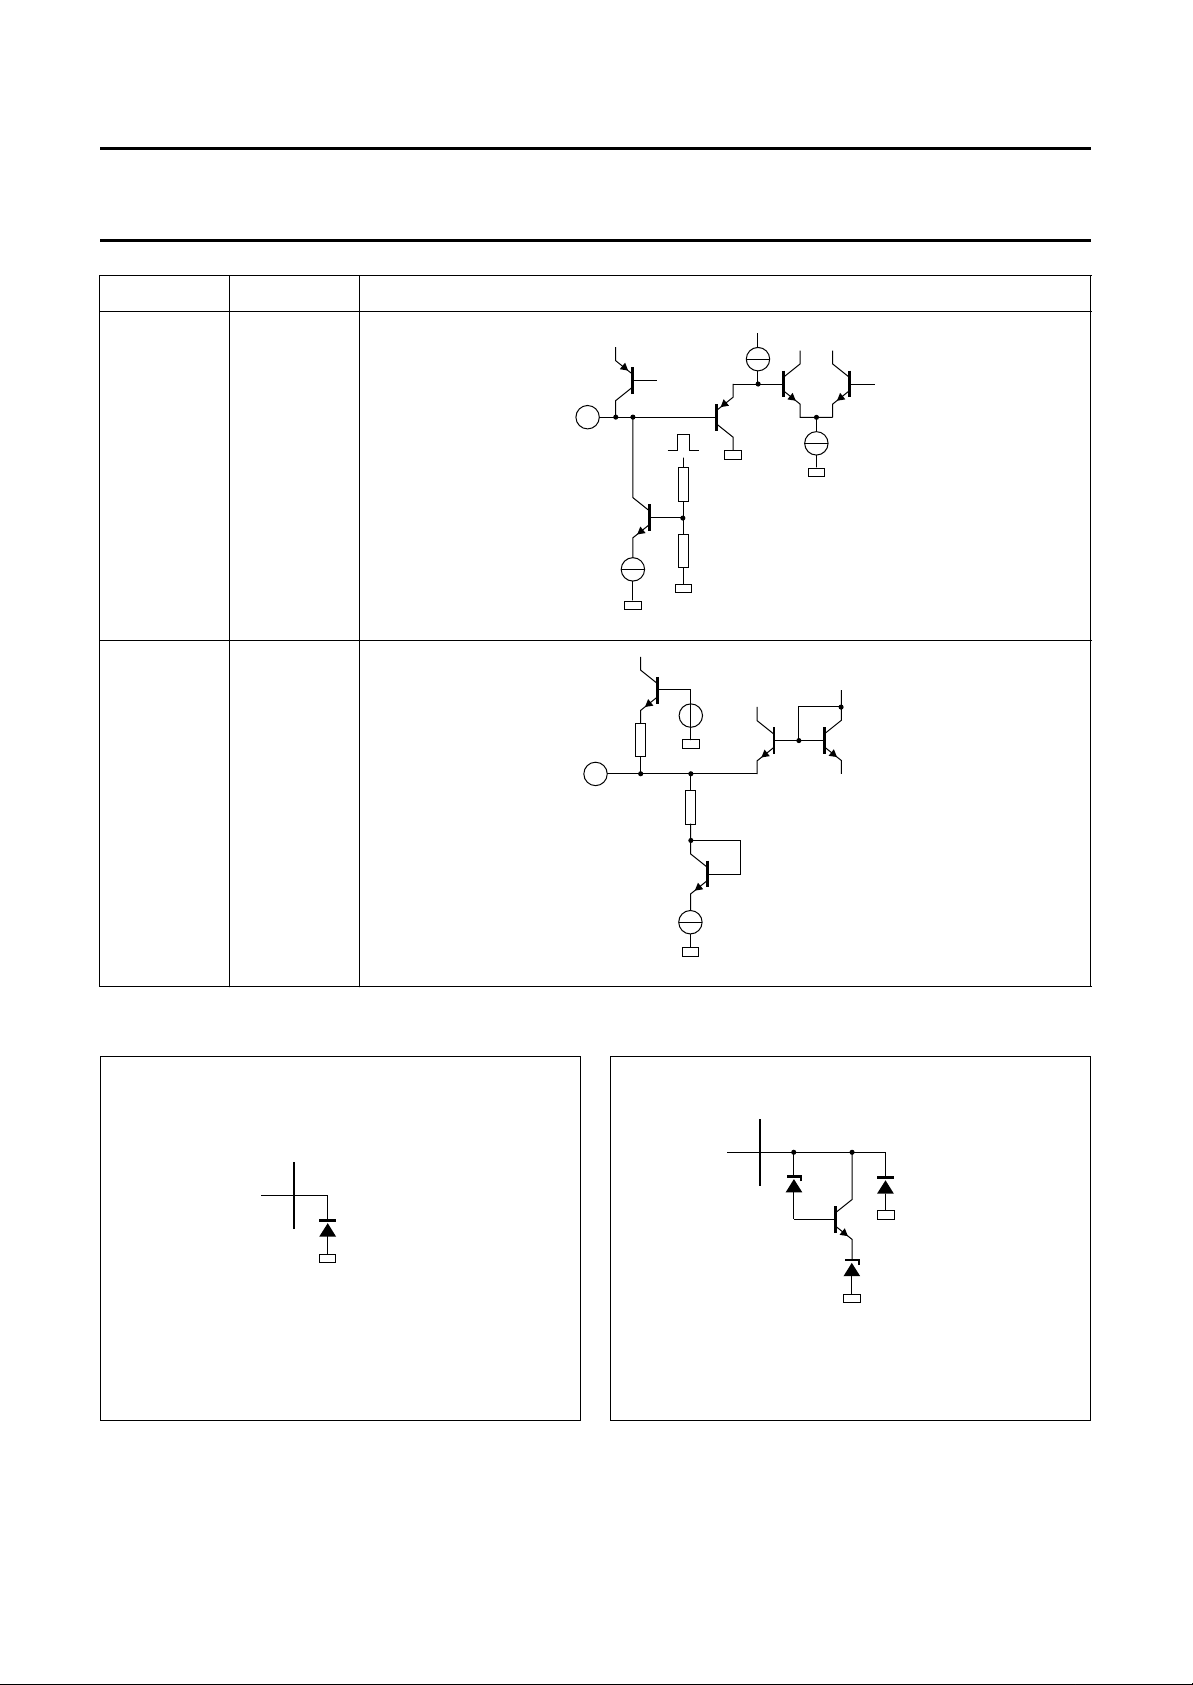
INTERNAL CIRCUITRY
Table 5 Internal circuitry of Fig.1
PIN SYMBOL INTERNAL CIRCUIT
1 HFLB
2 XRAY
3 BOP
1
1.5 kΩ
7 x
MBG561
5 kΩ
2
6.25 V
MBG562
3
1996 Jul 18 34
5.3 V
MBG563
Page 35
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
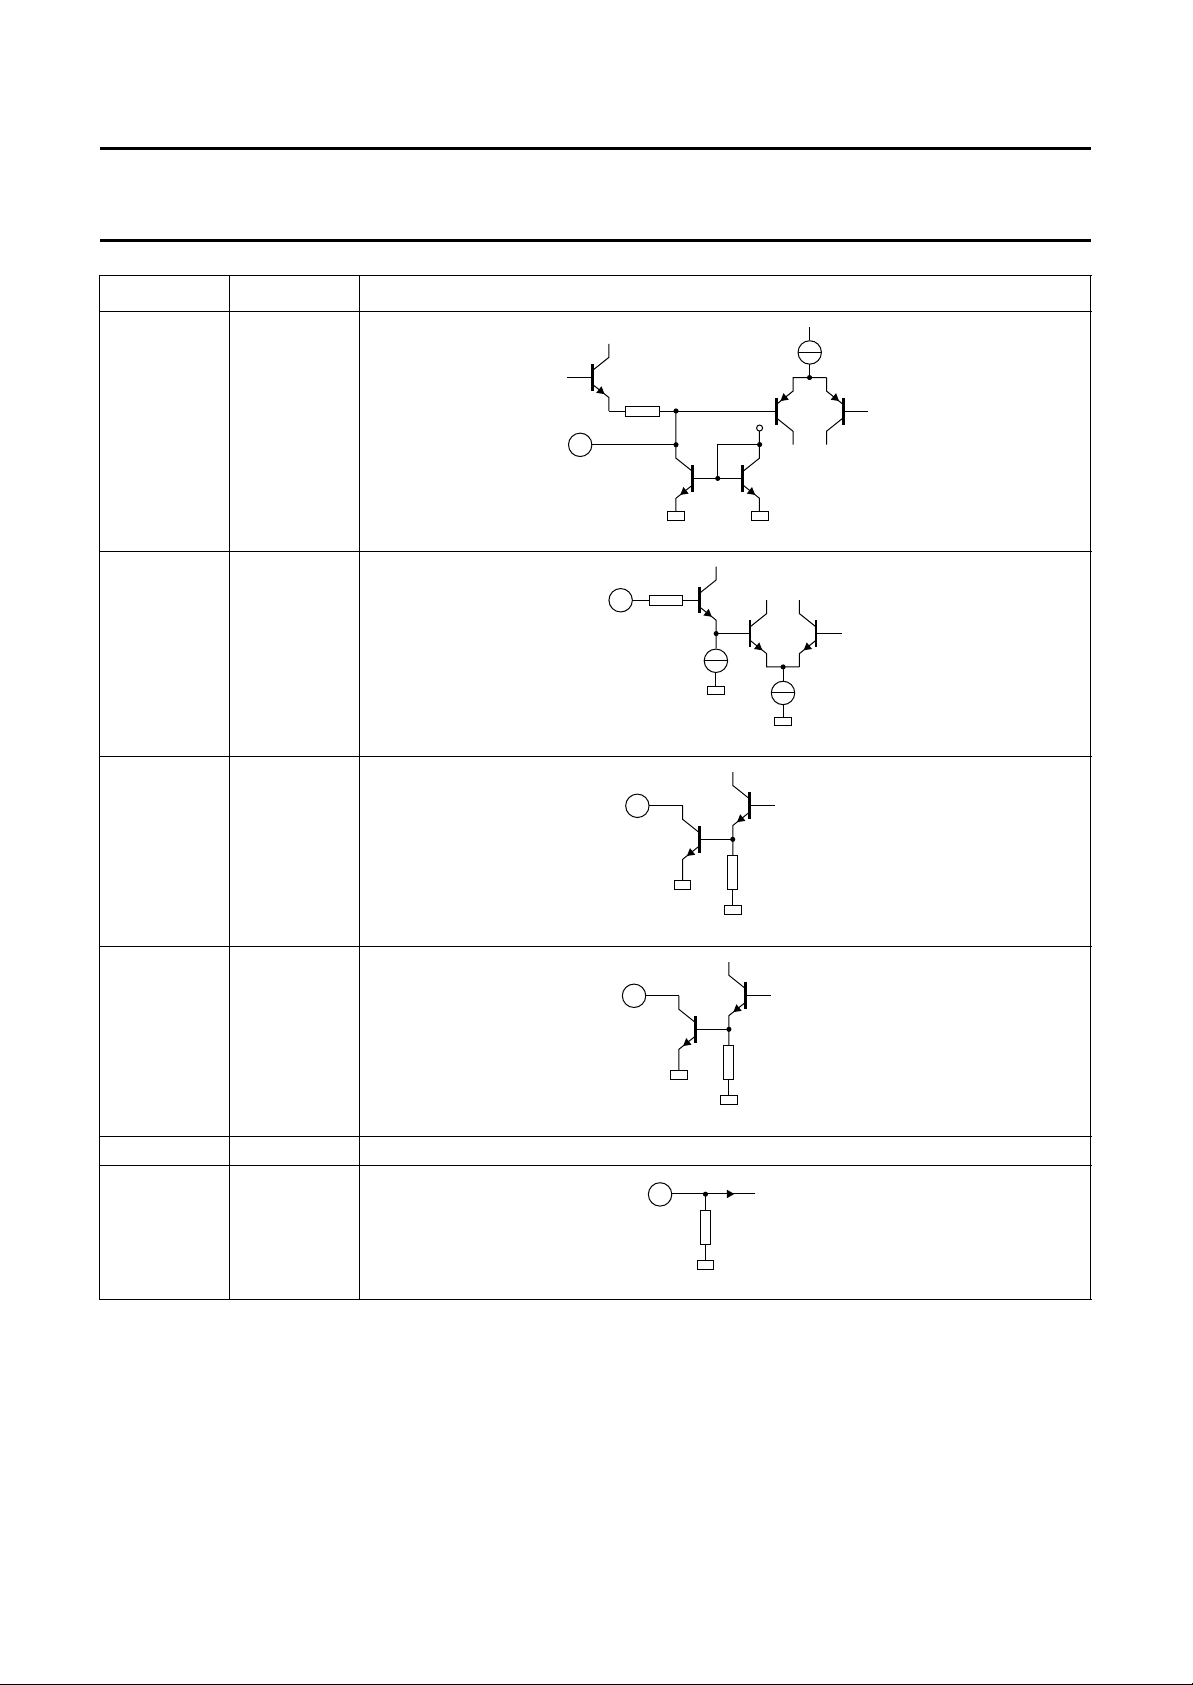
PIN SYMBOL INTERNAL CIRCUIT
4 BSENS
4
MBG564
5 BIN
5
MBG565
6 BDRV
6
7 HDRV
7
8 PGND power ground, connected to substrate
9V
CC
9
MBG566
MBG567
MBG568
1996 Jul 18 35
Page 36
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
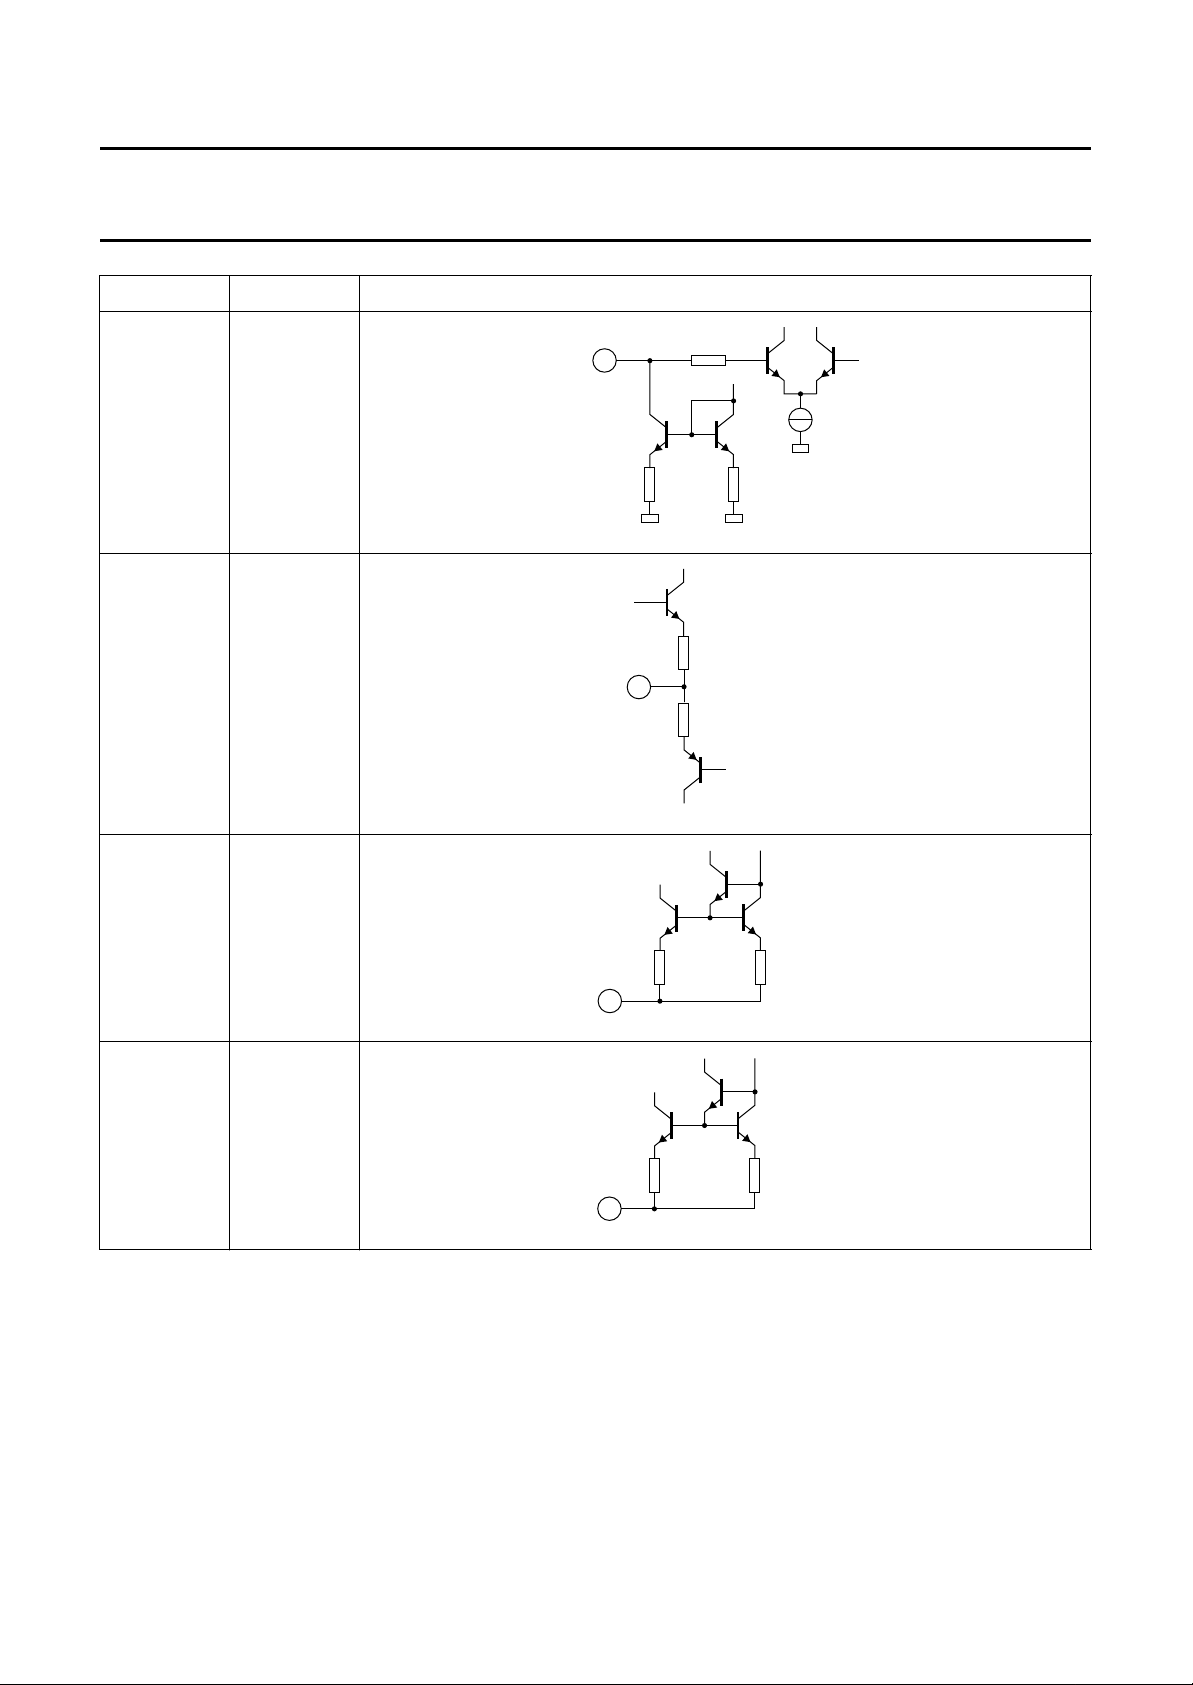
PIN SYMBOL INTERNAL CIRCUIT
10 FOCUS
10
11 EWDRV
11
1 kΩ
MBG569
108 Ω
108 Ω
12 VOUT2
13 VOUT1
MBG570
12
13
MBG571
MBG572
1996 Jul 18 36
Page 37
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
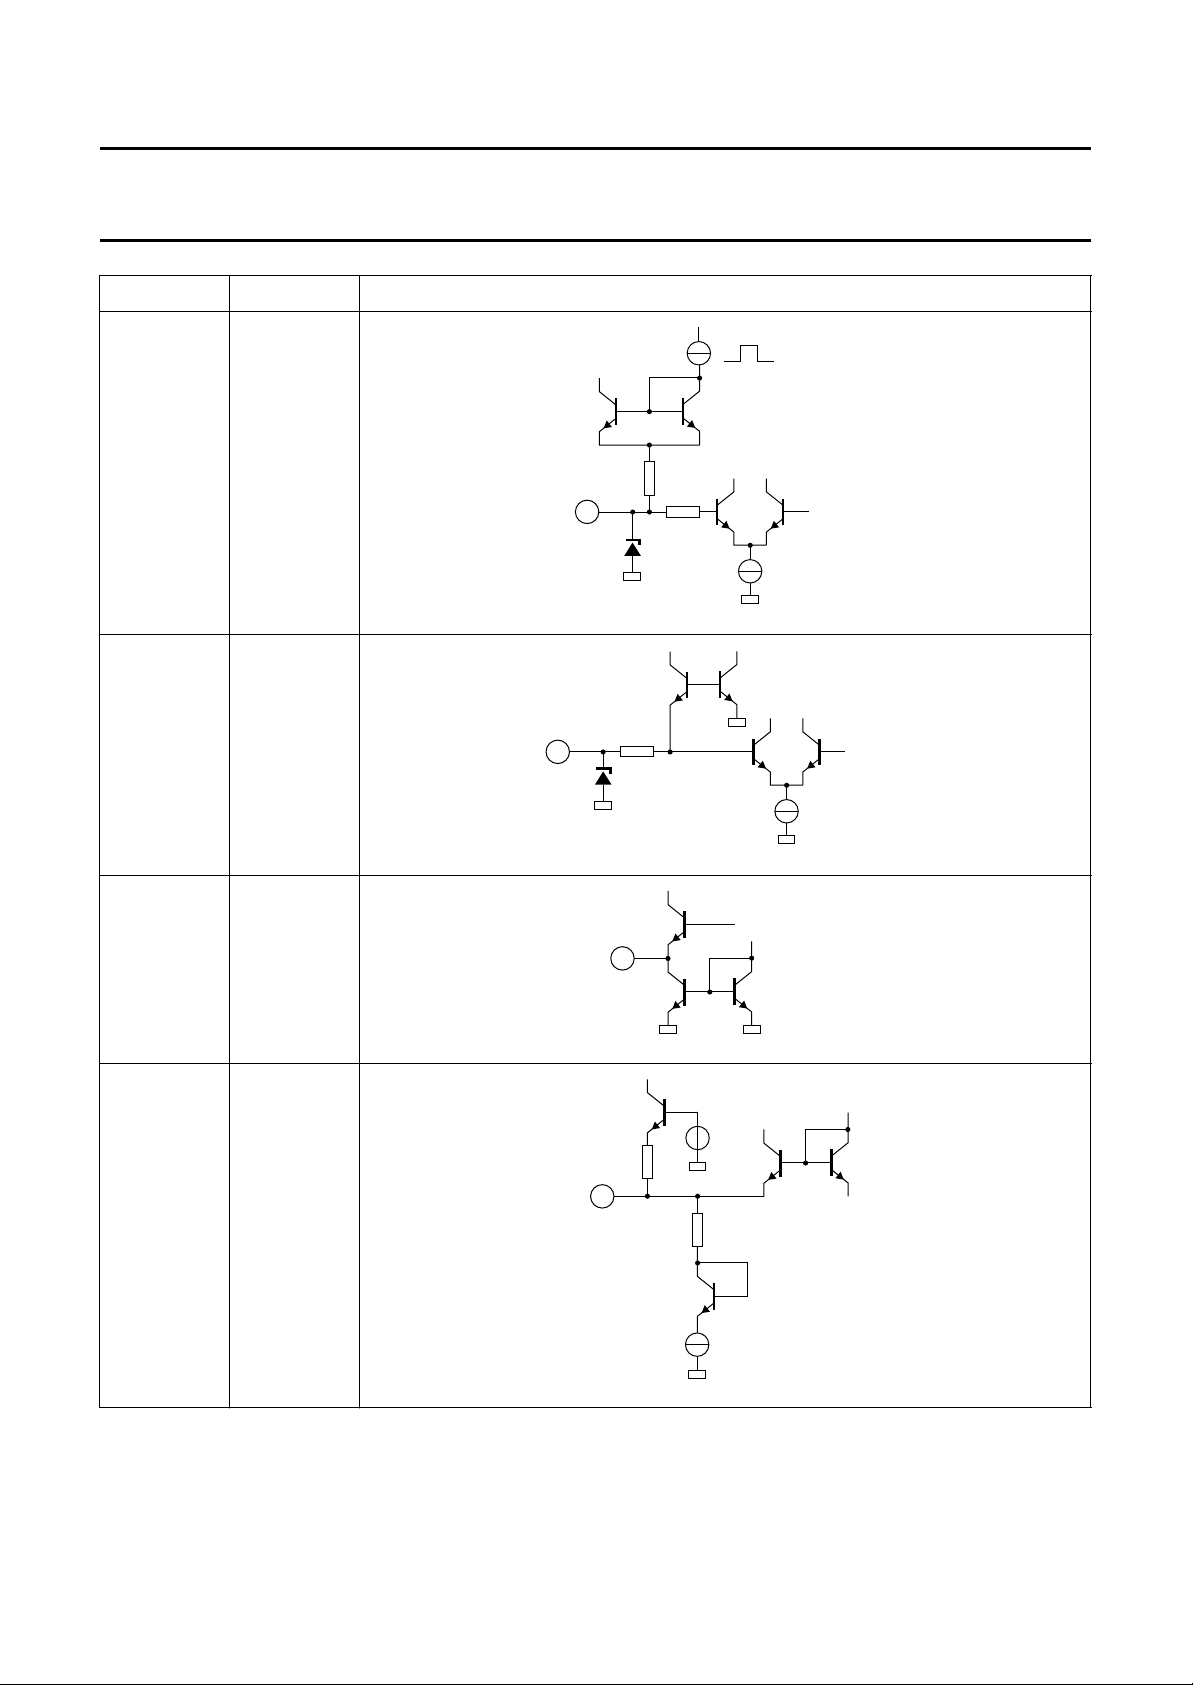
PIN SYMBOL INTERNAL CIRCUIT
14 VSYNC
100 Ω
14
2 kΩ
7.3 V
15 HSYNC
1.28 V
1.4 V
MBG573
16 CLBL
17 VPOS
16
7.2 kΩ
17
85 Ω
2 V
1 kΩ
BE
15
1.4 V
MBG574
MBG575
5 V
1996 Jul 18 37
MBG576
Page 38
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
PIN SYMBOL INTERNAL CIRCUIT
18 VAMP
19 VSCOR
20 EWTRP
18
19
2 V
5 V
MBG577
5 V
MBG578
BE
20
1996 Jul 18 38
5 V
MBG579
Page 39
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
PIN SYMBOL INTERNAL CIRCUIT
21 EWPAR
22 VAGC
23 VREF
21
1 kΩ
22
5 V
MBG580
MBG581
24 VCAP
24
25 SGND signal ground
1996 Jul 18 39
23
3 V
MBG582
MBG583
Page 40
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
PIN SYMBOL INTERNAL CIRCUIT
26 HPLL1
26
5.5 V
MBG589
27 HBUF
27
28 HREF
29 HCAP
30 HPOS
MBG584
76 Ω
28
7.7 V
29
1.7 V
7.7 V
1 kΩ
30
4.3 V
MBG586
2.525 V
MBG585
1996 Jul 18 40
Page 41
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
PIN SYMBOL INTERNAL CIRCUIT
31 HPLL2
32 EWWID
7.7 V
31
HFLB
MBG587
Electrostatic discharge (ESD) protection
pin
MBG559
7.2 kΩ
32
2 V
1 kΩ
BE
5 V
MBG588
pin
7.3 V
7.3 V
MBG560
Fig.19 ESD protection for pins 4, 10 to 13 and 16.
1996 Jul 18 41
Fig.20 ESD protection for pins 2 to 4, 17 to 24 and
26 to 32.
Page 42
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
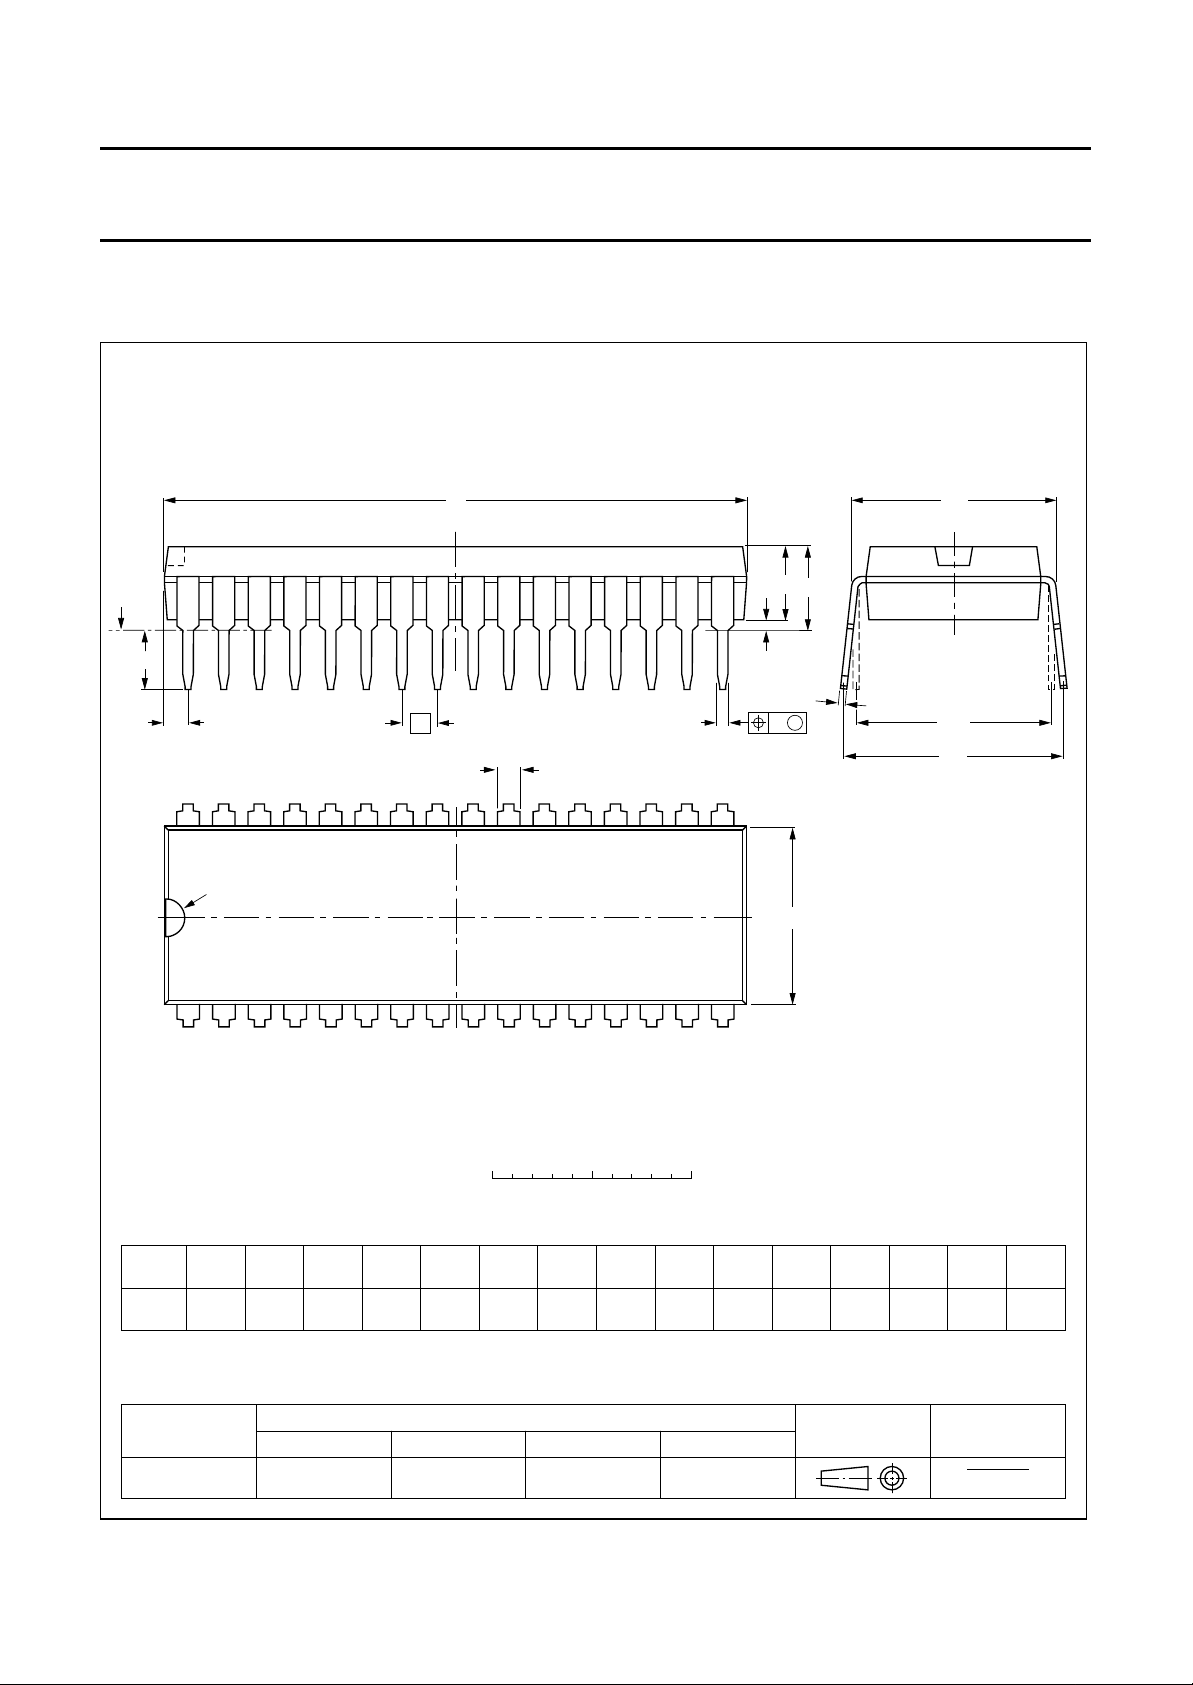
PACKAGE OUTLINE
SDIP32: plastic shrink dual in-line package; 32 leads (400 mil)
D
seating plane
L
Z
32
pin 1 index
e
b
SOT232-1
M
E
A
2
A
A
1
w M
b
1
17
E
c
(e )
M
1
H
1
0 5 10 mm
scale
DIMENSIONS (mm are the original dimensions)
A
A
A
UNIT b
Note
1. Plastic or metal protrusions of 0.25 mm maximum per side are not included.
mm
OUTLINE
VERSION
SOT232-1
max.
4.7 0.51 3.8
12
min.
max.
IEC JEDEC EIAJ
1.3
0.8
b
1
0.53
0.40
REFERENCES
cEe M
0.32
0.23
(1) (1)
D
29.4
28.5
1996 Jul 18 42
9.1
8.7
16
(1)
Z
L
3.2
2.8
EUROPEAN
PROJECTION
M
10.7
10.2
E
12.2
10.5
e
1
w
H
0.181.778 10.16
ISSUE DATE
92-11-17
95-02-04
max.
1.6
Page 43
Philips Semiconductors Preliminary specification
Autosync Deflection Controller (ASDC) TDA4855
SOLDERING
Introduction
There is no soldering method that is ideal for all IC
packages. Wave soldering is often preferred when
through-hole and surface mounted components are mixed
on one printed-circuit board. However, wave soldering is
not always suitable for surface mounted ICs, or for
printed-circuits with high population densities. In these
situations reflow soldering is often used.
This text gives a very brief insight to a complex technology.
A more in-depth account of soldering ICs can be found in
our
“IC Package Databook”
Soldering by dipping or by wave
The maximum permissible temperature of the solder is
260 °C; solder at this temperature must not be in contact
with the joint for more than 5 seconds. The total contact
time of successive solder waves must not exceed
5 seconds.
DEFINITIONS
Data sheet status
Objective specification This data sheet contains target or goal specifications for product development.
Preliminary specification This data sheet contains preliminary data; supplementary data may be published later.
Product specification This data sheet contains final product specifications.
(order code 9398 652 90011).
The device may be mounted up to the seating plane, but
the temperature of the plastic body must not exceed the
specified maximum storage temperature (T
printed-circuit board has been pre-heated, forced cooling
may be necessary immediately after soldering to keep the
temperature within the permissible limit.
Repairing soldered joints
Apply a low voltage soldering iron (less than 24 V) to the
lead(s) of the package, below the seating plane or not
more than 2 mm above it. If the temperature of the
soldering iron bit is less than 300 °C it may remain in
contact for up to 10 seconds. If the bit temperature is
between 300 and 400 °C, contact may be up to 5 seconds.
stg max
). If the
Limiting values
Limiting values given are in accordance with the Absolute Maximum Rating System (IEC 134). Stress above one or
more of the limiting values may cause permanent damage to the device. These are stress ratings only and operation
of the device at these or at any other conditions above those given in the Characteristics sections of the specification
is not implied. Exposure to limiting values for extended periods may affect device reliability.
Application information
Where application information is given, it is advisory and does not form part of the specification.
LIFE SUPPORT APPLICATIONS
These products are not designed for use in life support appliances, devices, or systems where malfunction of these
products can reasonably be expected to result in personal injury. Philips customers using or selling these products for
use in such applications do so at their own risk and agree to fully indemnify Philips for any damages resulting from such
improper use or sale.
1996 Jul 18 43
Page 44
Philips Semiconductors – a worldwide company
Argentina: see South America
Australia: 34 Waterloo Road, NORTH RYDE, NSW 2113,
Tel. +61 2 9805 4455, Fax. +61 2 9805 4466
Austria: Computerstr. 6, A-1101 WIEN, P.O. Box 213,
Tel. +43 1 60 101, Fax. +43 1 60 101 1210
Belarus: Hotel Minsk Business Center, Bld. 3, r. 1211, Volodarski Str. 6,
220050 MINSK, Tel. +375 172 200 733, Fax. +375 172 200 773
Belgium: see The Netherlands
Brazil: see South America
Bulgaria: Philips Bulgaria Ltd., Energoproject, 15th floor,
51 James Bourchier Blvd., 1407 SOFIA,
Tel. +359 2 689 211, Fax. +359 2 689 102
Canada: PHILIPS SEMICONDUCTORS/COMPONENTS,
Tel. +1 800 234 7381, Fax. +1 708 296 8556
China/Hong Kong: 501 Hong Kong Industrial Technology Centre,
72 Tat Chee Avenue, Kowloon Tong, HONG KONG,
Tel. +852 2319 7888, Fax. +852 2319 7700
Colombia: see South America
Czech Republic: see Austria
Denmark: Prags Boulevard 80, PB 1919, DK-2300 COPENHAGEN S,
Tel. +45 32 88 2636, Fax. +45 31 57 1949
Finland: Sinikalliontie 3, FIN-02630 ESPOO,
Tel. +358 615 800, Fax. +358 615 80920
France: 4 Rue du Port-aux-Vins, BP317, 92156 SURESNES Cedex,
Tel. +33 1 40 99 6161, Fax. +33 1 40 99 6427
Germany: Hammerbrookstraße 69, D-20097 HAMBURG,
Tel. +49 40 23 52 60, Fax. +49 40 23 536 300
Greece: No. 15, 25th March Street, GR 17778 TAVROS,
Tel. +30 1 4894 339/911, Fax. +30 1 4814 240
Hungary: see Austria
India: Philips INDIA Ltd, Shivsagar Estate, A Block, Dr. Annie Besant Rd.
Worli, MUMBAI 400 018, Tel. +91 22 4938 541, Fax. +91 22 4938 722
Indonesia: see Singapore
Ireland: Newstead, Clonskeagh, DUBLIN 14,
Tel. +353 1 7640 000, Fax. +353 1 7640 200
Israel: RAPAC Electronics, 7 Kehilat Saloniki St, TEL AVIV 61180,
Tel. +972 3 645 0444, Fax. +972 3 648 1007
Italy: PHILIPS SEMICONDUCTORS, Piazza IV Novembre 3,
20124 MILANO, Tel. +39 2 6752 2531, Fax. +39 2 6752 2557
Japan: Philips Bldg 13-37, Kohnan 2-chome, Minato-ku, TOKYO 108,
Tel. +81 3 3740 5130, Fax. +81 3 3740 5077
Korea: Philips House, 260-199 Itaewon-dong, Yongsan-ku, SEOUL,
Tel. +82 2 709 1412, Fax. +82 2 709 1415
Malaysia: No. 76 Jalan Universiti, 46200 PETALING JAYA, SELANGOR,
Tel. +60 3 750 5214, Fax. +60 3 757 4880
Mexico: 5900 Gateway East, Suite 200, EL PASO, TEXAS 79905,
Tel. +1 800 234 7381, Fax. +1 708 296 8556
Middle East: see Italy
Netherlands: Postbus 90050, 5600 PB EINDHOVEN, Bldg. VB,
Tel. +31 40 27 83749, Fax. +31 40 27 88399
New Zealand: 2 Wagener Place, C.P.O. Box 1041, AUCKLAND,
Tel. +64 9 849 4160, Fax. +64 9 849 7811
Norway: Box 1, Manglerud 0612, OSLO,
Tel. +47 22 74 8000, Fax. +47 22 74 8341
Philippines: Philips Semiconductors Philippines Inc.,
106 Valero St. Salcedo Village, P.O. Box 2108 MCC, MAKATI,
Metro MANILA, Tel. +63 2 816 6380, Fax. +63 2 817 3474
Poland: Ul. Lukiska 10, PL 04-123 WARSZAWA,
Tel. +48 22 612 2831, Fax. +48 22 612 2327
Portugal: see Spain
Romania: see Italy
Russia: Philips Russia, Ul. Usatcheva 35A, 119048 MOSCOW,
Tel. +7 095 926 5361, Fax. +7 095 564 8323
Singapore: Lorong 1, Toa Payoh, SINGAPORE 1231,
Tel. +65 350 2538, Fax. +65 251 6500
Slovakia: see Austria
Slovenia: see Italy
South Africa: S.A. PHILIPS Pty Ltd., 195-215 Main Road Martindale,
2092 JOHANNESBURG, P.O. Box 7430 Johannesburg 2000,
Tel. +27 11 470 5911, Fax. +27 11 470 5494
South America: Rua do Rocio 220, 5th floor, Suite 51,
04552-903 São Paulo, SÃO PAULO - SP, Brazil,
Tel. +55 11 821 2333, Fax. +55 11 829 1849
Spain: Balmes 22, 08007 BARCELONA,
Tel. +34 3 301 6312, Fax. +34 3 301 4107
Sweden: Kottbygatan 7, Akalla, S-16485 STOCKHOLM,
Tel. +46 8 632 2000, Fax. +46 8 632 2745
Switzerland: Allmendstrasse 140, CH-8027 ZÜRICH,
Tel. +41 1 488 2686, Fax. +41 1 481 7730
Taiwan: PHILIPS TAIWAN Ltd., 23-30F, 66,
Chung Hsiao West Road, Sec. 1, P.O. Box 22978,
TAIPEI 100, Tel. +886 2 382 4443, Fax. +886 2 382 4444
Thailand: PHILIPS ELECTRONICS (THAILAND) Ltd.,
209/2 Sanpavuth-Bangna Road Prakanong, BANGKOK 10260,
Tel. +66 2 745 4090, Fax. +66 2 398 0793
Turkey: Talatpasa Cad. No. 5, 80640 GÜLTEPE/ISTANBUL,
Tel. +90 212 279 2770, Fax. +90 212 282 6707
Ukraine: PHILIPS UKRAINE, 2A Akademika Koroleva str., Office 165,
252148 KIEV, Tel. +380 44 476 0297/1642, Fax. +380 44 476 6991
United Kingdom: Philips Semiconductors Ltd., 276 Bath Road, Hayes,
MIDDLESEX UB3 5BX, Tel. +44 181 730 5000, Fax. +44 181 754 8421
United States: 811 East Arques Avenue, SUNNYVALE, CA 94088-3409,
Tel. +1 800 234 7381, Fax. +1 708 296 8556
Uruguay: see South America
Vietnam: see Singapore
Yugoslavia: PHILIPS, Trg N. Pasica 5/v, 11000 BEOGRAD,
Tel. +381 11 825 344, Fax.+381 11 635 777
For all other countries apply to: Philips Semiconductors, Marketing & Sales Communications,
Building BE-p, P.O. Box 218, 5600 MD EINDHOVEN, The Netherlands, Fax. +31 40 27 24825
© Philips Electronics N.V. 1996 SCA50
All rights are reserved. Reproduction in whole or in part is prohibited without the prior written consent of the copyright owner.
The information presented in this document does not form part of any quotation or contract, is believed to be accurate and reliable and may be changed
without notice. No liability will be accepted by the publisher for any consequence of its use. Publication thereof does not convey nor imply any license
under patent- or other industrial or intellectual property rights.
Printed in The Netherlands 537021/51/01/pp44 Date of release: 1996 Jul 18 Document order number: 9397 750 00973
Internet: http://www.semiconductors.philips.com/ps/
(1) TDA4855_1 June 26, 1996 11:51 am
 Loading...