

Page 1
INTEGRATED CIRCUITS
DATA SH EET
TDA3629
Light position controller
Product specification
File under Integrated Circuits, IC18
1996 Sep 04
Page 2

Philips Semiconductors Product specification
Light position controller TDA3629
FEATURES
• Low positional error
• Low noise sensitivity due to hysteresis
• Low supply current
• Thermally protected
GENERAL DESCRIPTION
The Light position controller (Leucht Weiten Steller, LWS)
is a monolithic integrated circuit intended to be used in
passenger cars. This device adapts the elevation of the
light beam of the head light of the car to a state defined by
the car driver using a potentiometer on the dashboard.
• Broken wire and short-circuit indication on SET input
• Brake function by short-circuiting the motor
• Hysteresis level set externally.
QUICK REFERENCE DATA
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
I
P(ss)
supply current, steady state note 1 − − 6 mA
IP− Im supply current, motor active Im < 900 mA − − 80 mA
Vm output voltage Im < 700 mA VP− 2.9− − V
Im output current VP≥ 12.3 V 670 − − mA
I
motor switch on current level VP= 12 V 6 9 12 µA
SET
Note
1. Steady state implies that the motor is not running (Im= 0) and V
= VFB= 0.5VP.
SET
ORDERING INFORMATION
TYPE NUMBER
NAME DESCRIPTION VERSION
TDA3629 DIP8
TDA3629T SO16
PACKAGE
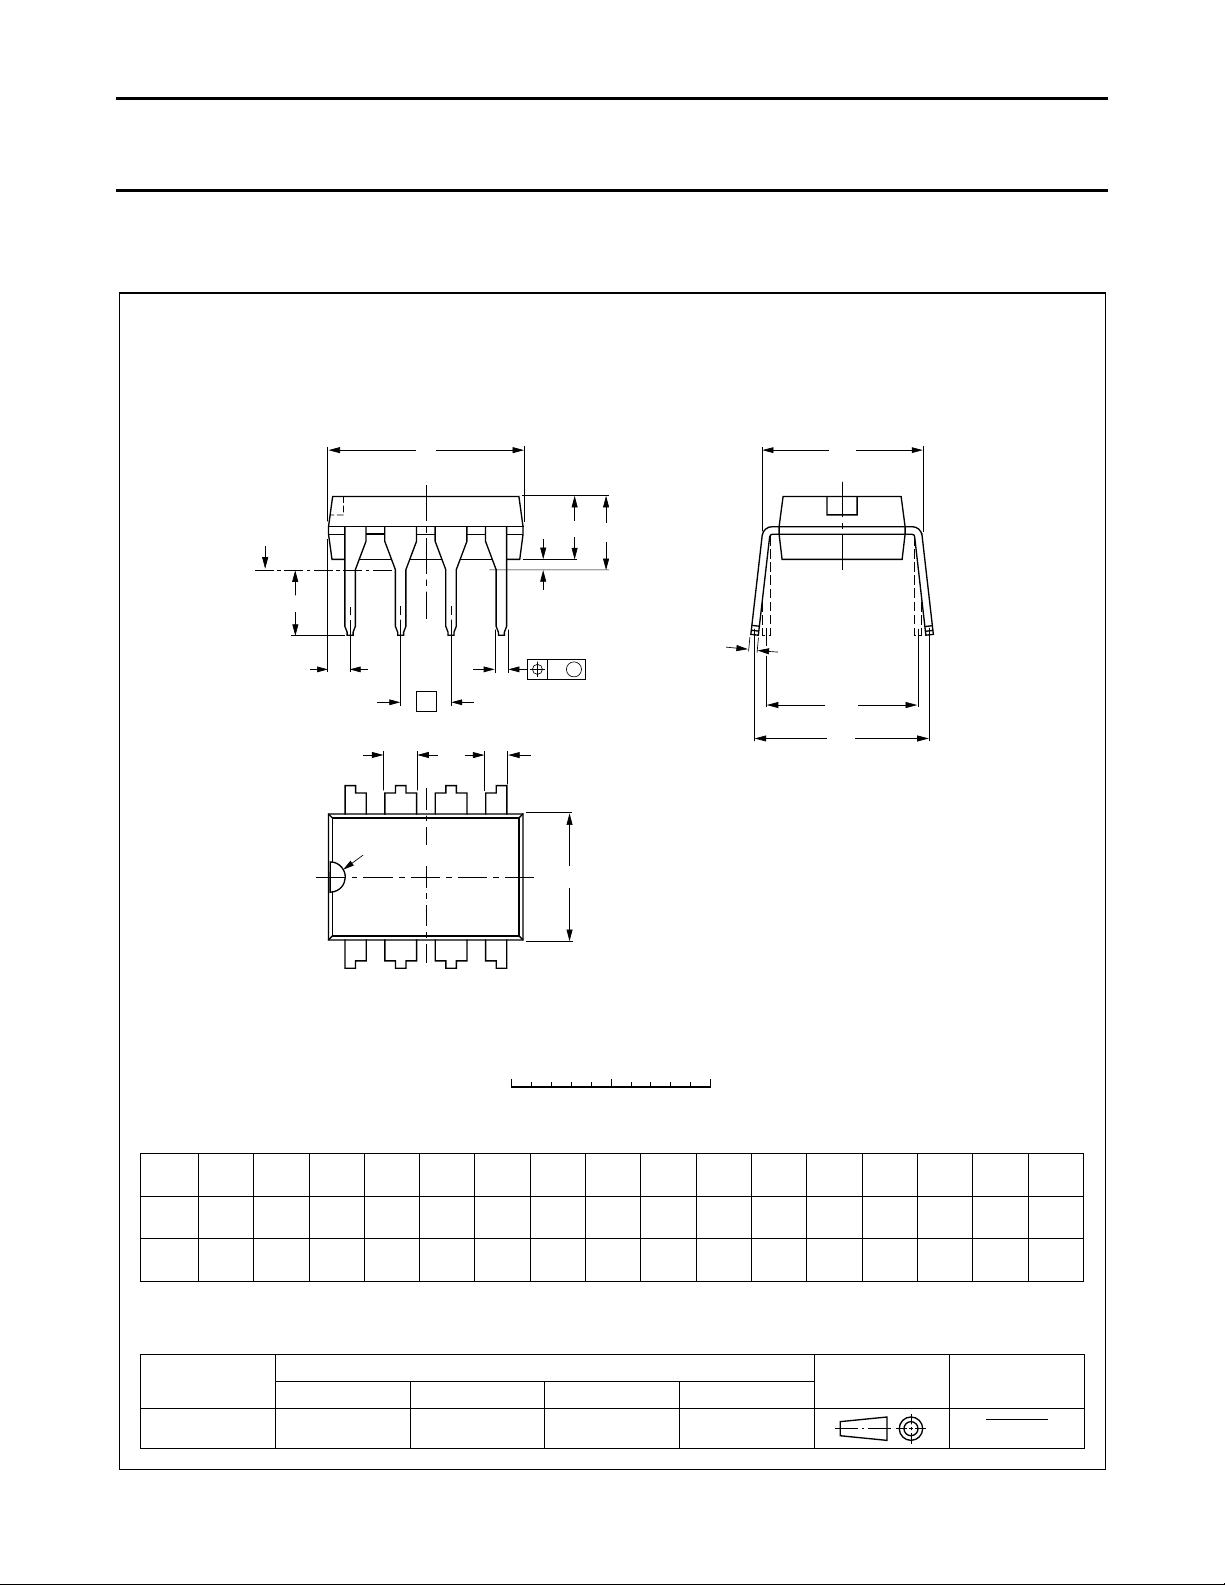
plastic dual in-line package; 8 leads (300 mil)
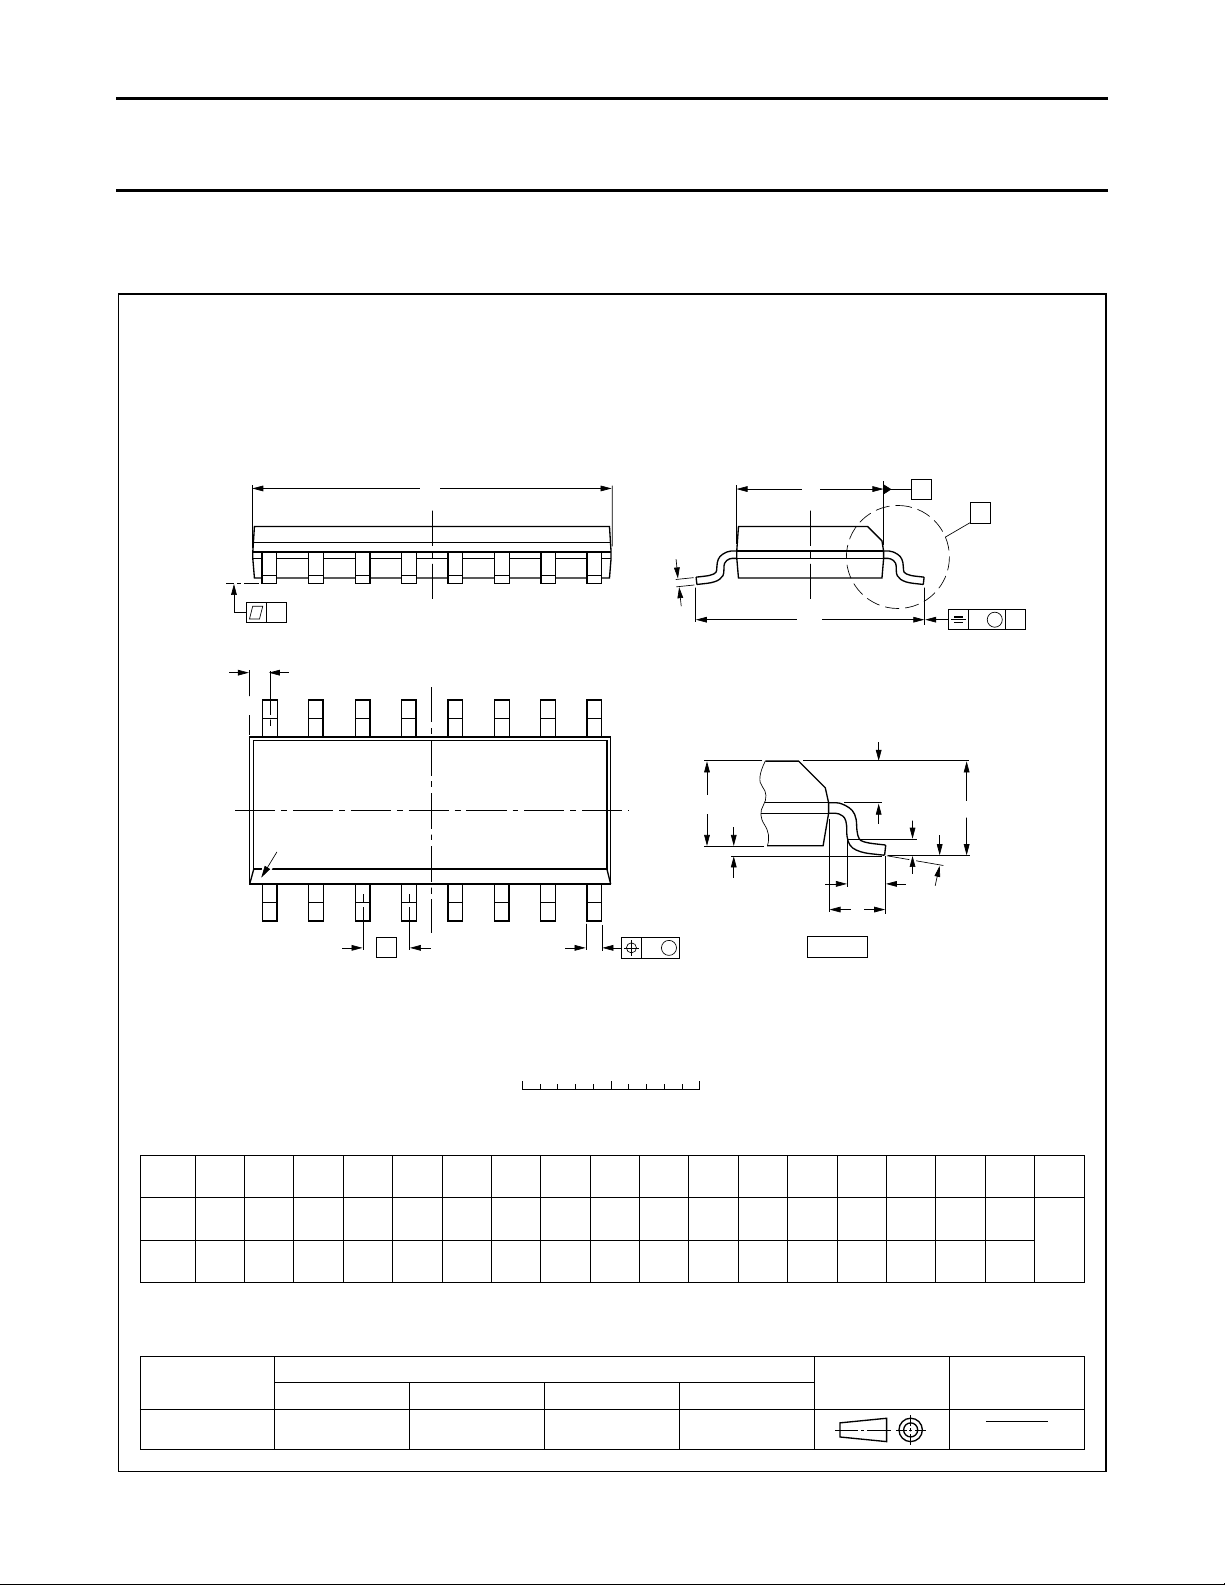
plastic small outline package; 16 leads; body width 3.9 mm
SOT97-1
SOT109-1
1996 Sep 04 2
Page 3
Philips Semiconductors Product specification
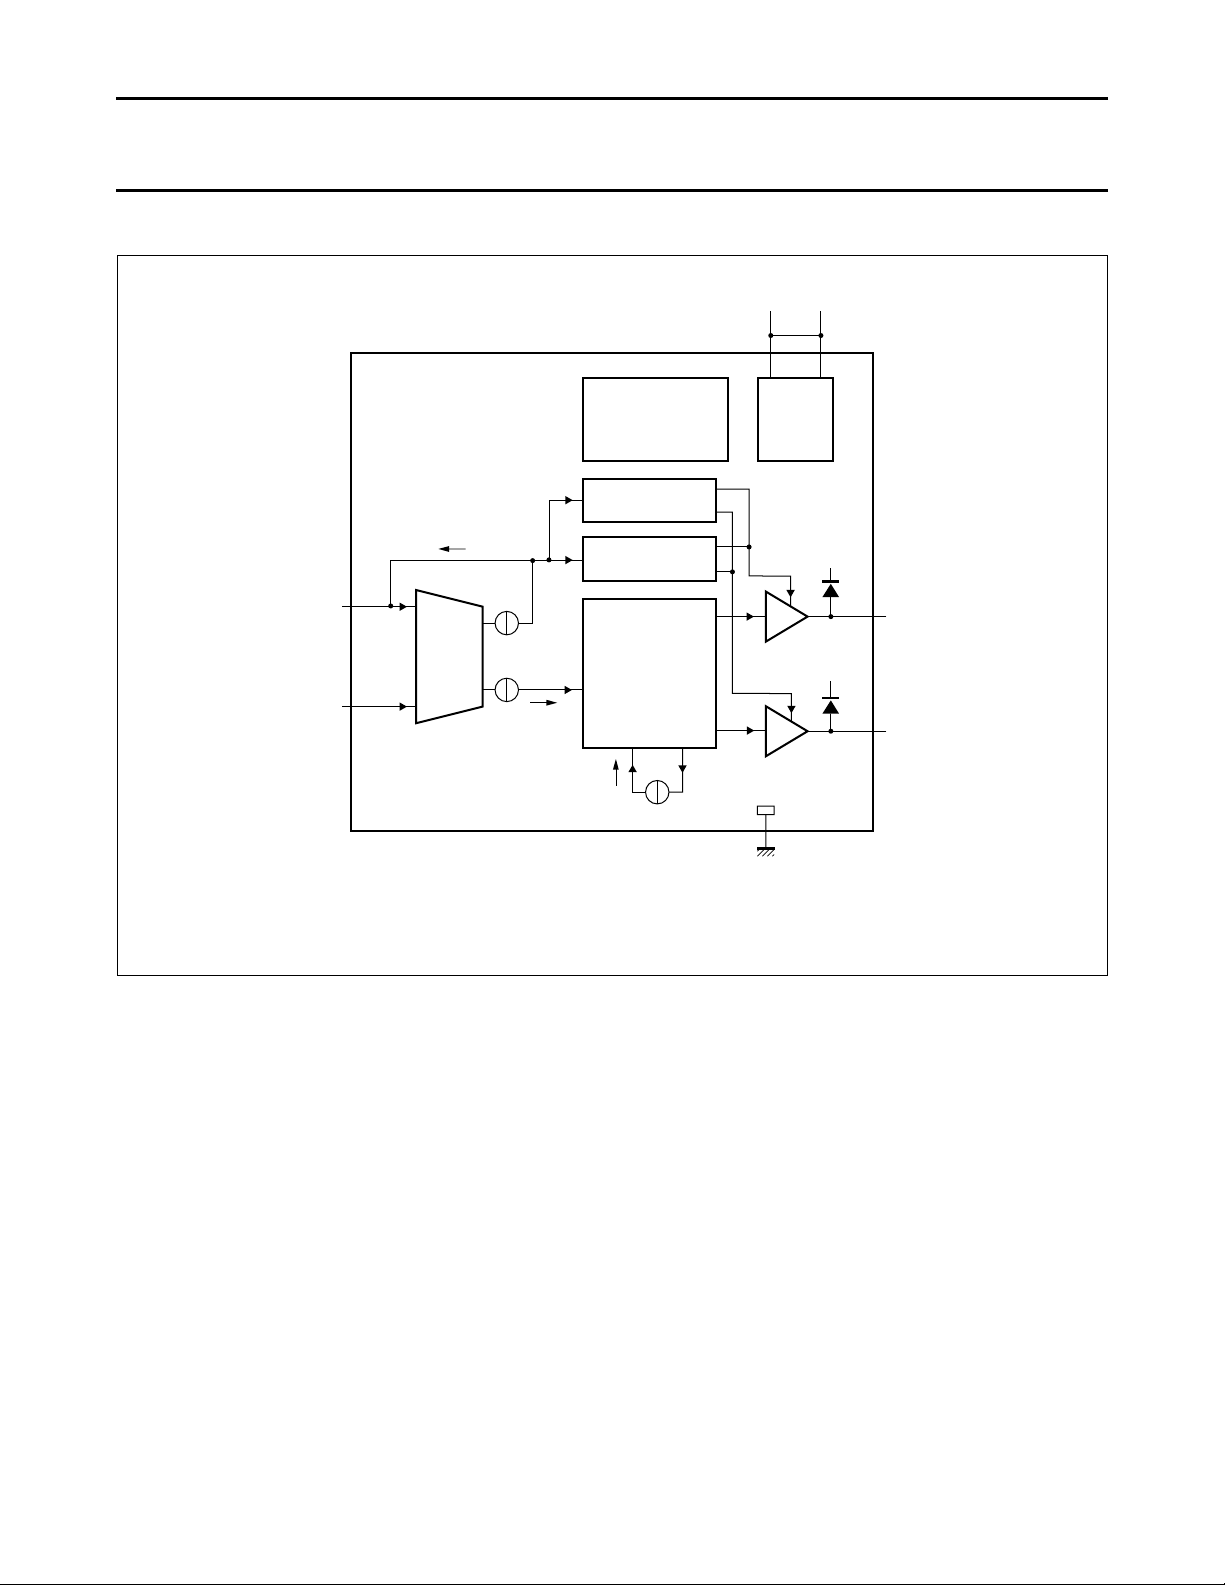
Fig.1 Block diagram.
handbook, full pagewidth
MGE632
INPUT
STAGE
SHORT-CIRCUIT
SUPPLY
BROKEN WIRE
PROTECTION
- OVER VOLTAGE
- UNDER VOLTAGE
- TEMPERATURE
WINDOWS
AND
COMPARATORS
V
P
V
P1
V
P
OUT1
OUTPUT
STAGES
OUT2
SET
7(12)2(5)
8(16)
1(1)
3(6)
5(9)
6(11)
FB
I
SET
I
SET
I
ref
V
P2
TDA3629
Pin numbers in parenthesis represent the TDA3629T.
Light position controller TDA3629
BLOCK DIAGRAM
1996 Sep 04 3
Page 4

Philips Semiconductors Product specification
Fig.2 Pin configuration TDA3629.
handbook, halfpage
MGE633
TDA3629
1
2
3
4
8
7
6
5
FB
V
P1
OUT1
n.c.
SET
V
P2
OUT2
GND
Fig.3 Pin configuration TDA3629T.
handbook, halfpage
TDA3629T
MGE634
1
2
3
4
5
6
7
8
FB
n.c.
n.c.
n.c.
V
P1
OUT1
n.c.
n.c.
SET
n.c.
n.c.
n.c.
V
P2
OUT2
n.c.
GND
16
15
14
13
12
11
10
9
Light position controller TDA3629
PINNING
SYMBOL
DESCRIPTION
TDA3629 TDA3629T
FB 1 1 feedback input
PIN
V
P1
2 5 supply voltage 1
OUT1 3 6 output 1
(1)
n.c.
4 2 to 4, 7, 8, 10, 13 to 15 not connected
GND 5 9 ground
OUT2 6 11 output 2
V
P2
7 12 supply voltage 2
SET 8 16 set input
Note
1. The pins which are not electrically connected should be connected to a copper area of the printed-circuit board which
is as large as possible to improve heat transfer.
1996 Sep 04 4
Page 5

Philips Semiconductors Product specification
Fig.4 Conversion gain.
handbook, halfpage
MGE635
100
position
(%)
0
0
V
SET(min)
V
SET(max)
V
SET
(V)
V
b
Light position controller TDA3629
FUNCTIONAL DESCRIPTION
The device is intended to control the elevation of the light
beam of a head light of a passenger car. The driver can
control the elevation of the light beam by rotating a
potentiometer on the dashboard (the setting
potentiometer). The device adapts the elevation of the light
beam by activating the control motor. The elevation of the
head light is fed back to the device by a second
potentiometer (the feedback potentiometer).
This feedback potentiometer is mechanically coupled to
the motor.
The device operates only when the supply voltage is within
certain limits. The device is switched off outside these
boundaries. The under voltage detection detects whether
the supply voltage is below the under voltage threshold.
The motor will not be activated when this occurs, but it
remains short-circuited by the output stages.
The over voltage will switch off the total device when the
supply voltage is higher than the over voltage threshold.
A thermal protection circuit becomes active if the junction
temperature exceeds a value of approximately 160 °C.
This circuit will reduce the motor current, which will result
in a lower dissipation and hence a lower chip temperature.
This condition will only occur when the motor is blocked at
high ambient temperature.
A detection of a broken wire of the slider of the setting
potentiometer is included because it will be connected to
the device by a wire several meters long. This detection
circuit prevents the motor from rotating when the wire is
broken. In this event the brake will remain active.
The protection of V
from rotating when the voltage at the V
to VP circuit prevents the motor
SET
input is above
SET
the threshold value. This can be used to detect whether
the wire from the slider of the setting potentiometer is
short-circuited to the battery line. A protection of V
SET
short-circuited to ground is also present. The motor will be
stopped if V
The shaded areas in Fig.4 represent the parts where the
becomes lower than the threshold level.
SET
short-circuit protection stages are active. Figure 4 shows
that a position of 0 mm can not be reached, neither can a
position of 100%. The minimum position that can be
reached depends on the battery voltage Vb, although the
maximum position does not.
The device is protected against electrical transients which
may occur in an automotive environment. The device will
shut off when positive transients on the battery line occur
(see Figs 7 and 8). The motor will not be short-circuited in
this event. The flyback diodes, illustrated in Fig.1, will
remain present. The state of the output stages at the
moment when the transient starts is preserved by internal
flip-flops. Negative transients on the battery line
(see Figs 7 and 8) will result in a set short-circuited to
ground fault detection, because it will result in a voltage at
the setting input which is below the short-circuited to
ground threshold. The device however discharges the
electrolytic capacitor during these transients. It will stop
functioning when the resulting supply voltage becomes too
low.
1996 Sep 04 5
Page 6
Philips Semiconductors Product specification
Fig.5 Timing diagram.
handbook, full pagewidth
V
SET
V
FB
I
SET
I
ref
absolute
motor
current
V2
V1
V1
0
0
T1T2T
3
T
4
time
MGE636
V2
Light position controller TDA3629
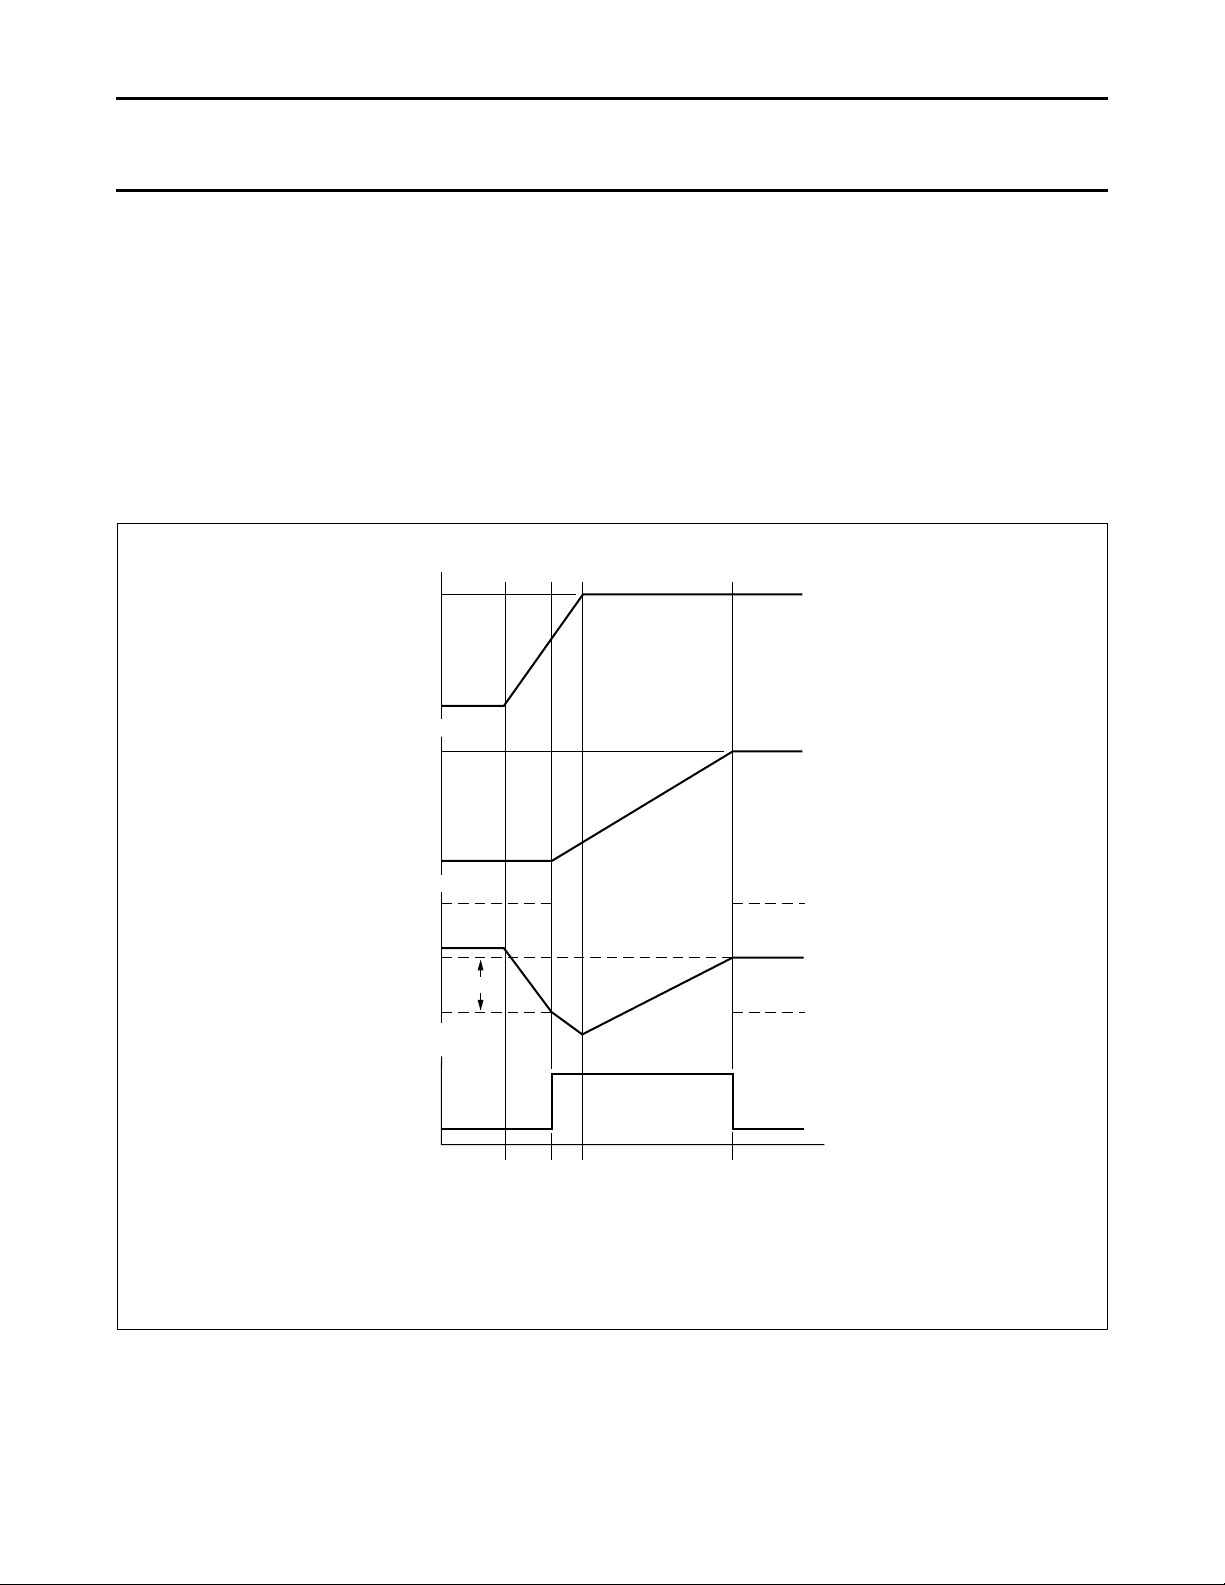
The timing can be divided into several parts starting from
a steady state (see Fig.5, the starting point, and Fig.10 for
the application diagram): in this state (until T1) a large
reference current is active, indicated by the dotted lines.
When the setting potentiometer is rotated (started at T
and indicated by V
higher than the reference current I
) and the input current I
SET
(at time T2), the motor
ref
SET
1
becomes
will start and the input current will decrease. At the same
time the reference current is switched to a low level.
During rotation of the motor the input current will decrease
until it becomes lower than this low reference current;
this occurs at time T4. At this time the brake becomes
active, the motor will stop and the reference current is set
to the higher value. The brake is realized by
short-circuiting the motor. In general: this system does not
use a linear adaptation strategy but an on-off strategy.
This results in high accuracy and low noise sensitivity.
The brake is active at any time during normal operation
when the motor is not active. The polarity of the feedback
potentiometer should be such that the voltage at the slider
of the feedback potentiometer increases when OUT1 is
high and OUT2 is low.
1996 Sep 04 6
Page 7

Philips Semiconductors Product specification
Light position controller TDA3629
LIMITING VALUES
In accordance with the Absolute Maximum Rating System (IEC 134). All voltages are defined with respect to ground.
Positive currents flow into the device. Values measured in Fig.10.
SYMBOL PARAMETER CONDITIONS MIN. MAX. UNIT
V
V
V
T
T
T
V
R
t
block
P
n
es
stg
amb
vj
b, tr
L
supply voltage operating 8 18 V
non-operating −0.3 +50 V
voltage on any other pin −0.3 VP+ 0.3 V
electrostatic handling note 1 −3 +3 kV
storage temperature −55 +150 °C
ambient temperature −40 +105 °C
virtual junction temperature note 2 −50 +150 °C
voltage transients on V
b
note 3 −150 +100 V
load resistance note 4 10 − Ω
cumulative blocking time Im = 700 mA − 100 h
Notes
1. Human body model: equivalent to discharging a 100 pF capacitor through a 1.5 kΩ resistor.
2. In accordance with IEC 747-1. An alternative definition of virtual junction temperature Tvj is:
Tvj= T
the allowable combinations of power dissipation Pd and ambient temperature T
amb
+ Pd× R
th vj-amb
, where R
is a fixed value to be used for the calculation of Tvj. The rating for Tvj limits
th vj-amb
. Additional information is given in
amb
section “Thermal aspects” in chapter “Test and application information”.
3. Wave forms illustrated in Figs 7 and 8 applied to the application diagram, Fig.10.
4. Vb= 13 V; T
= 25 °C; duration 50 ms maximum; non repetitive.
amb
THERMAL CHARACTERISTICS
In accordance with IEC 747-1.
SYMBOL PARAMETER VALUE UNIT
R
th vj-amb
thermal resistance from junction to ambient in free air
TDA3629 100 K/W
TDA3629T 105 K/W
1996 Sep 04 7
Page 8
Philips Semiconductors Product specification
Light position controller TDA3629
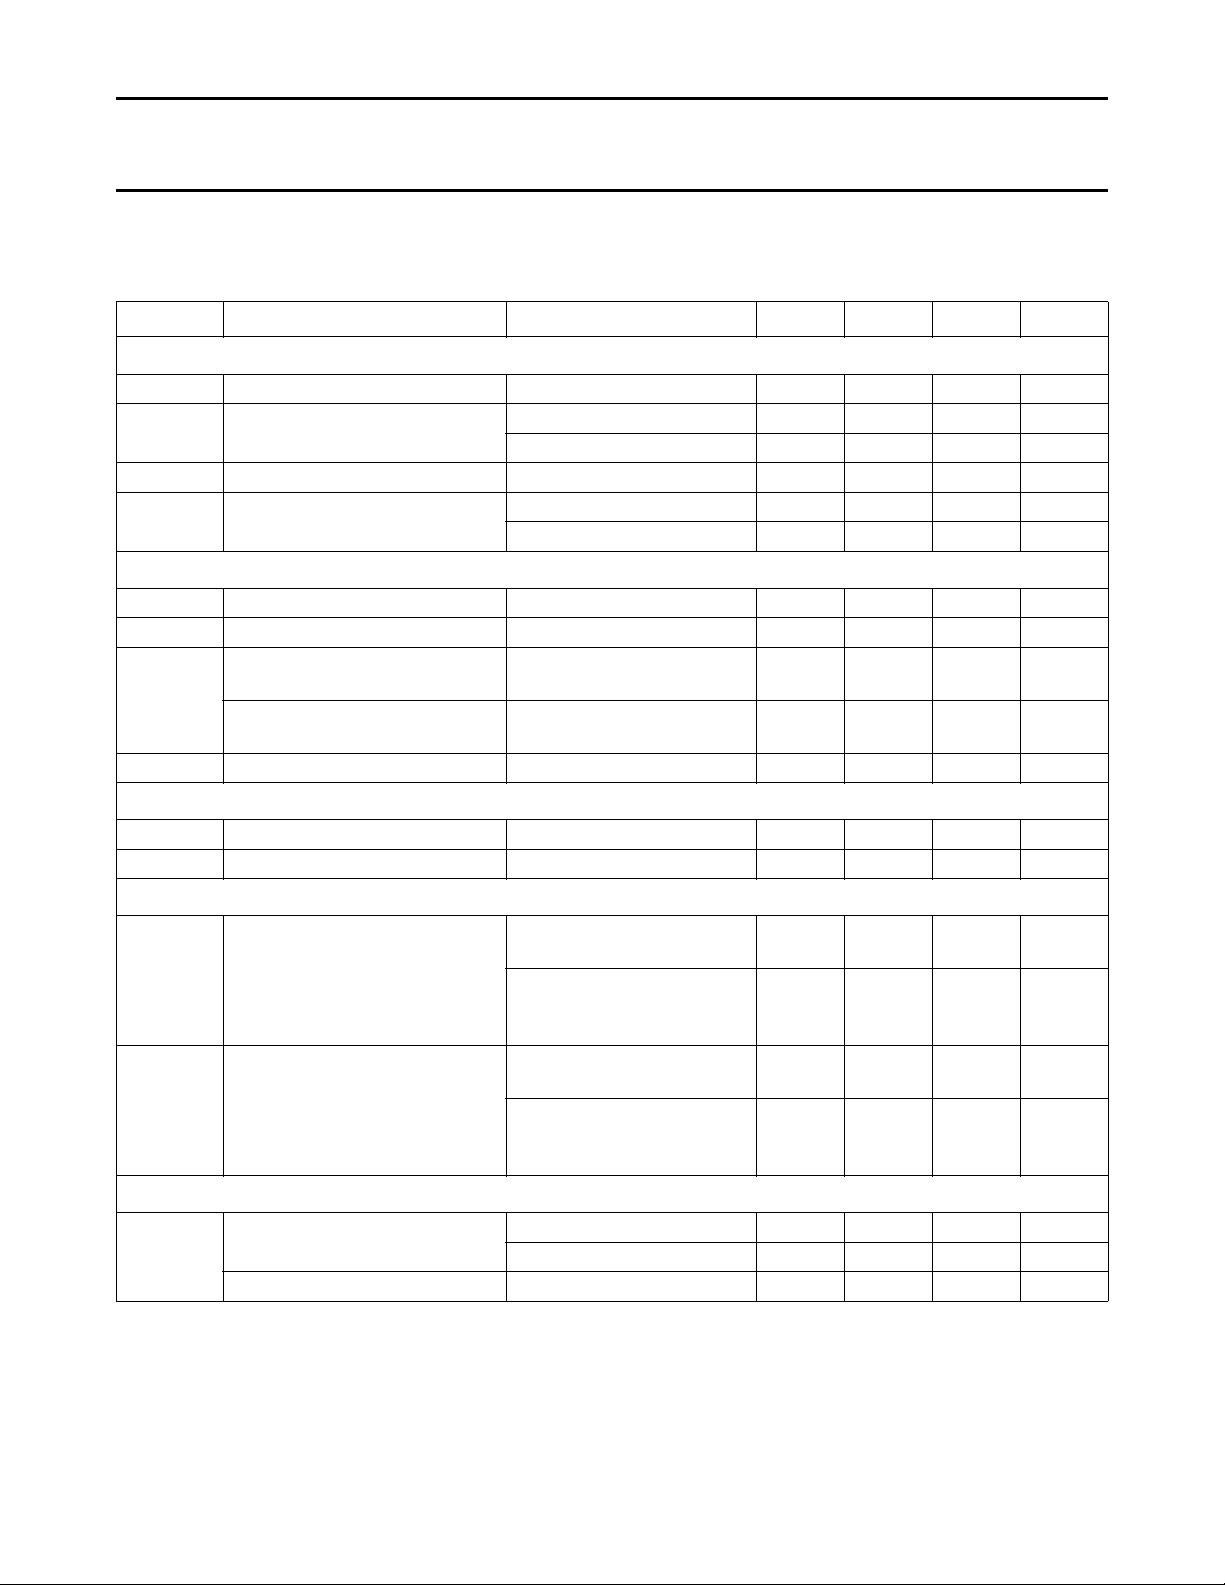
CHARACTERISTICS
VP= 12 V; RL= 14 Ω. All voltages are defined with respect to ground. Positive currents flow into the device.
Values measured in Fig.10 with R
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
Supply
V
P(min)
V
P(max)
I
P(ss)
under voltage threshold 6 − 8 V
over voltage threshold T
supply current, steady state note 1 − − 6 mA
IP− Im supply current, motor active Im < 400 mA; note 2 − − 40 mA
Setting input (SET)
V
SET
I
SET
V
SET(sc)
operating voltage 1.5 − 0.95VPV
input current R
wire short-circuited to ground
threshold
wire short-circuited to battery
threshold
∆V
SET
broken ground set pull-up note 3 − − 160 mV
Feedback input (FB)
V
FB
I
FB(max)
voltage 1.5 − 0.95VPV
maximum input current RFB> 20 kΩ −250 − +250 µA
Motor outputs
V
output voltage Im < 700 mA;
m
Im output current VP≥ 12.3 V;
= RFB= 20 kΩ; unless otherwise specified.
SET
= 25 °C 18 − 22 V
amb
T
= −40 to +105 °C 17.5 − 22.8 V
amb
Im < 900 mA; note 2 − − 80 mA
> 20 kΩ −250 − +250 µA
SET
output stages switched off − − 1 V
output stages switched off V
T
= 25 °C; note 2
amb
Im < 700 mA;
T
= −40 to +105 °C;
amb
note 2
T
= 25 °C; note 2
amb
VP≥ 12.3 V;
T
= −40 to +105 °C;
amb
note 2
P
− − V
VP− 2.9 − − V
VP− 3.4 − − V
670 − − mA
635 − − mA
Reference current
I
motor switch-on level VP= 12 V 6 9 12 µA
SET
VP= 18 V 9 13 17 µA
motor switch-off level − 2.5 − µA
1996 Sep 04 8
Page 9

Philips Semiconductors Product specification
Fig.6 Conditions for the test of note 3.
The 170 Ω, 830 Ω and 390 Ω resistors form the setting potentiometer in its worst case position. The given situation (combination of Vb, R
SET
and the
position of the set potentiometer) forms the worst case situation. The given maximum of ∆V
SET
guarantees that any other module, connected to the
same set potentiometer, will not start to activate its motor, when its motor switch-on level is higher than 0.01V
b
(R
SET
≥ 20 kΩ).
handbook, halfpage
MGE637
R
SET
V
SET, br
+V
b
battery
ground
830 Ω
390 Ω
170 Ω
REMAINDER OF
MODULE
ground wire not connected
+
−
Light position controller TDA3629
Notes to the characteristics
1. Steady state implies that the motor is not running (Im= 0) and V
2. This is only valid when the temperature protection is not active.
3. ∆V
is the difference in voltage on the set potentiometer between the situation when the ground wire is interrupted
SET
(V
) and voltage on the set potentiometer during normal operation (when V
SET, br
The conditions for this test are:
R
= 20 kΩ; Vb= 16 V; ∆V
SET
SET
= V
− 2.72 V; see Fig.6.
SET, br
= VFB= 0.5VP.
SET
= 0.17Vb= 2.72 V).
SET
QUALITY SPECIFICATION
The quality of this device is in accordance with
found in the
1996 Sep 04 9
“Quality reference Handbook”
“SNW-FQ-611 part E”
. The numbers of the quality specification can be
. The handbook can be ordered using the code 9397 750 00192.
Page 10
Philips Semiconductors Product specification
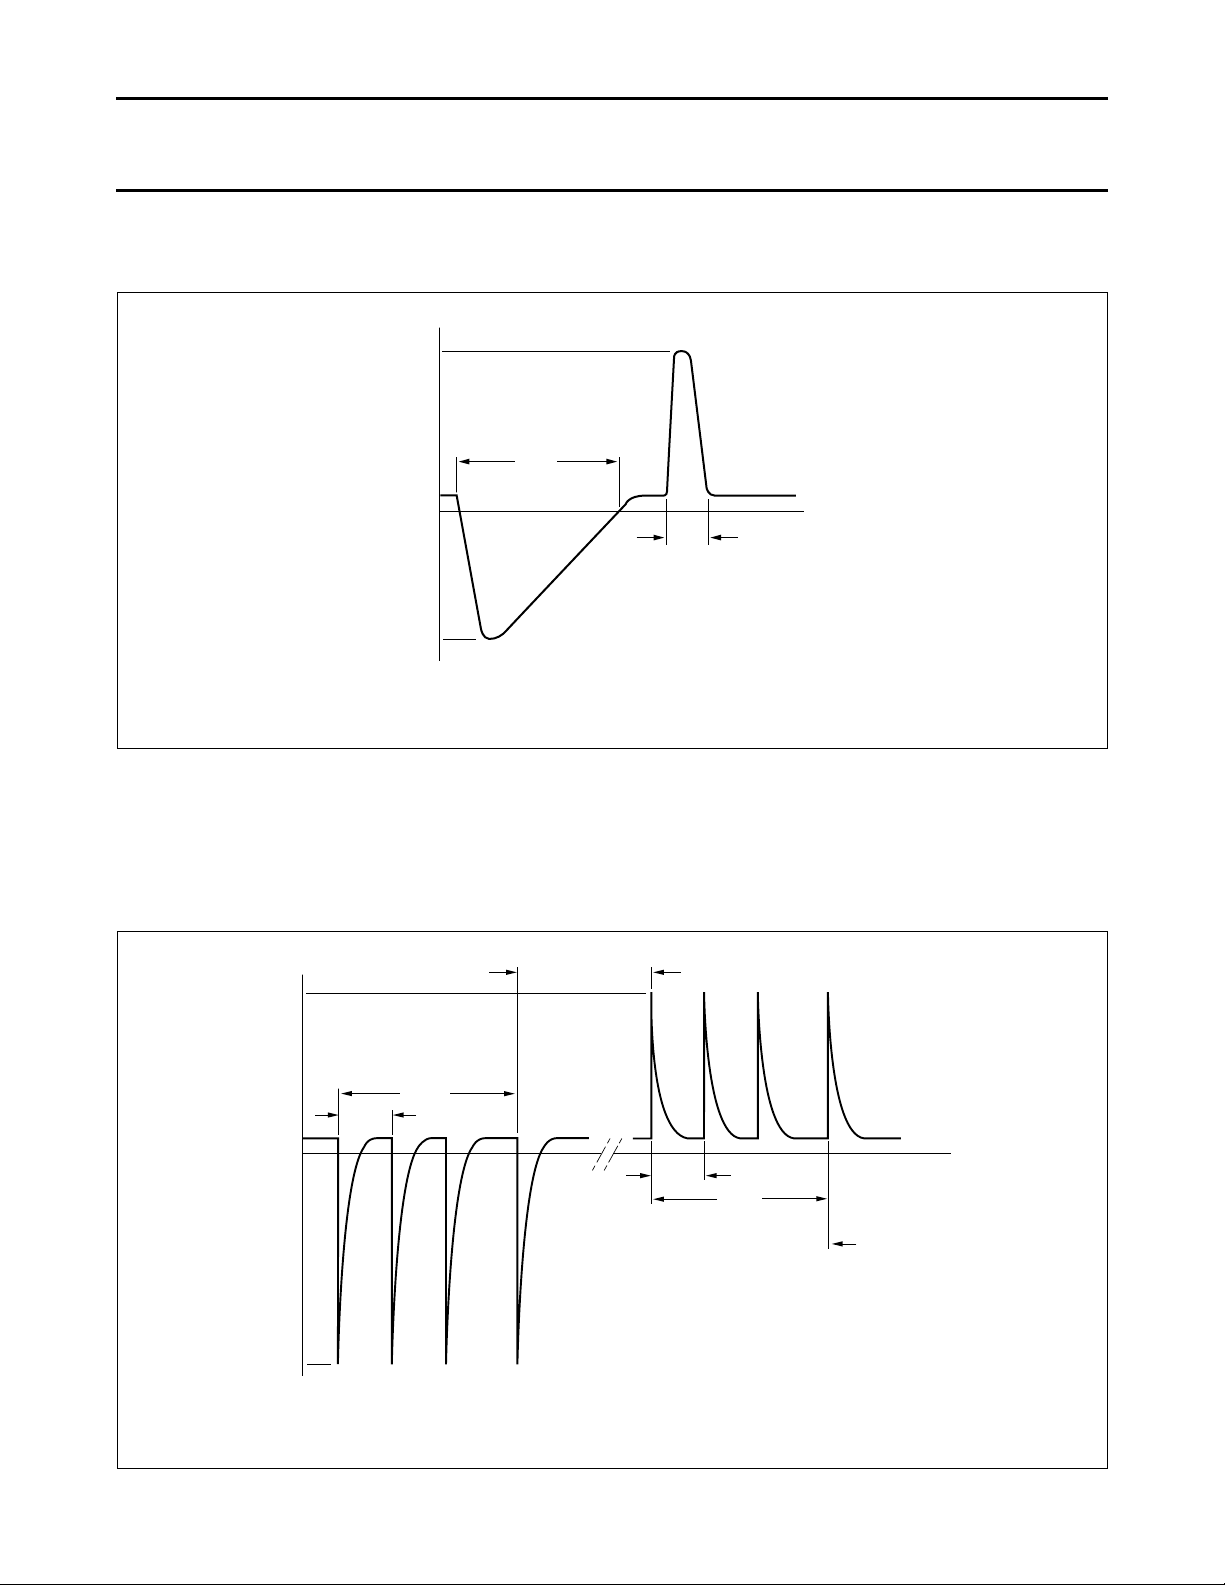
Fig.7 Worst case transients on Vb (continued in Fig.8).
handbook, halfpage
MGE638
2 ms
0.5 ms
time
PULSE 1
PULSE 2
12
112
V
b
(V)
0
−88
Fig.8 Worst case transients on Vb (continued from Fig.7).
handbook, full pagewidth
MGE639
100 µs
100 µs
10 ms
10 ms
PULSE 4
time
90 ms pause
90 ms pause
PULSE 3
12
112
V
b
(V)
0
−138
Light position controller TDA3629
TEST AND APPLICATION INFORMATION
Automotive transients
Worst case transients that may occur on the battery line Vb of the application (see Fig.10), are the pulses whose wave
forms and the corresponding values are as illustrated in Figs 7 and 8. The signal source which generates these pulses
(numbered pulses 1 and 2) has a series resistance (Ri) of 10 Ω. These pulses represent for instance the influence of
switching of inductors on the battery line. The signal source which generates pulses 3 and 4 has a series resistance of
50 Ω. These pulses represent for instance the influence of ignition on the battery line. Their repetition rate is 100 ms.
1996 Sep 04 10
Page 11
Philips Semiconductors Product specification
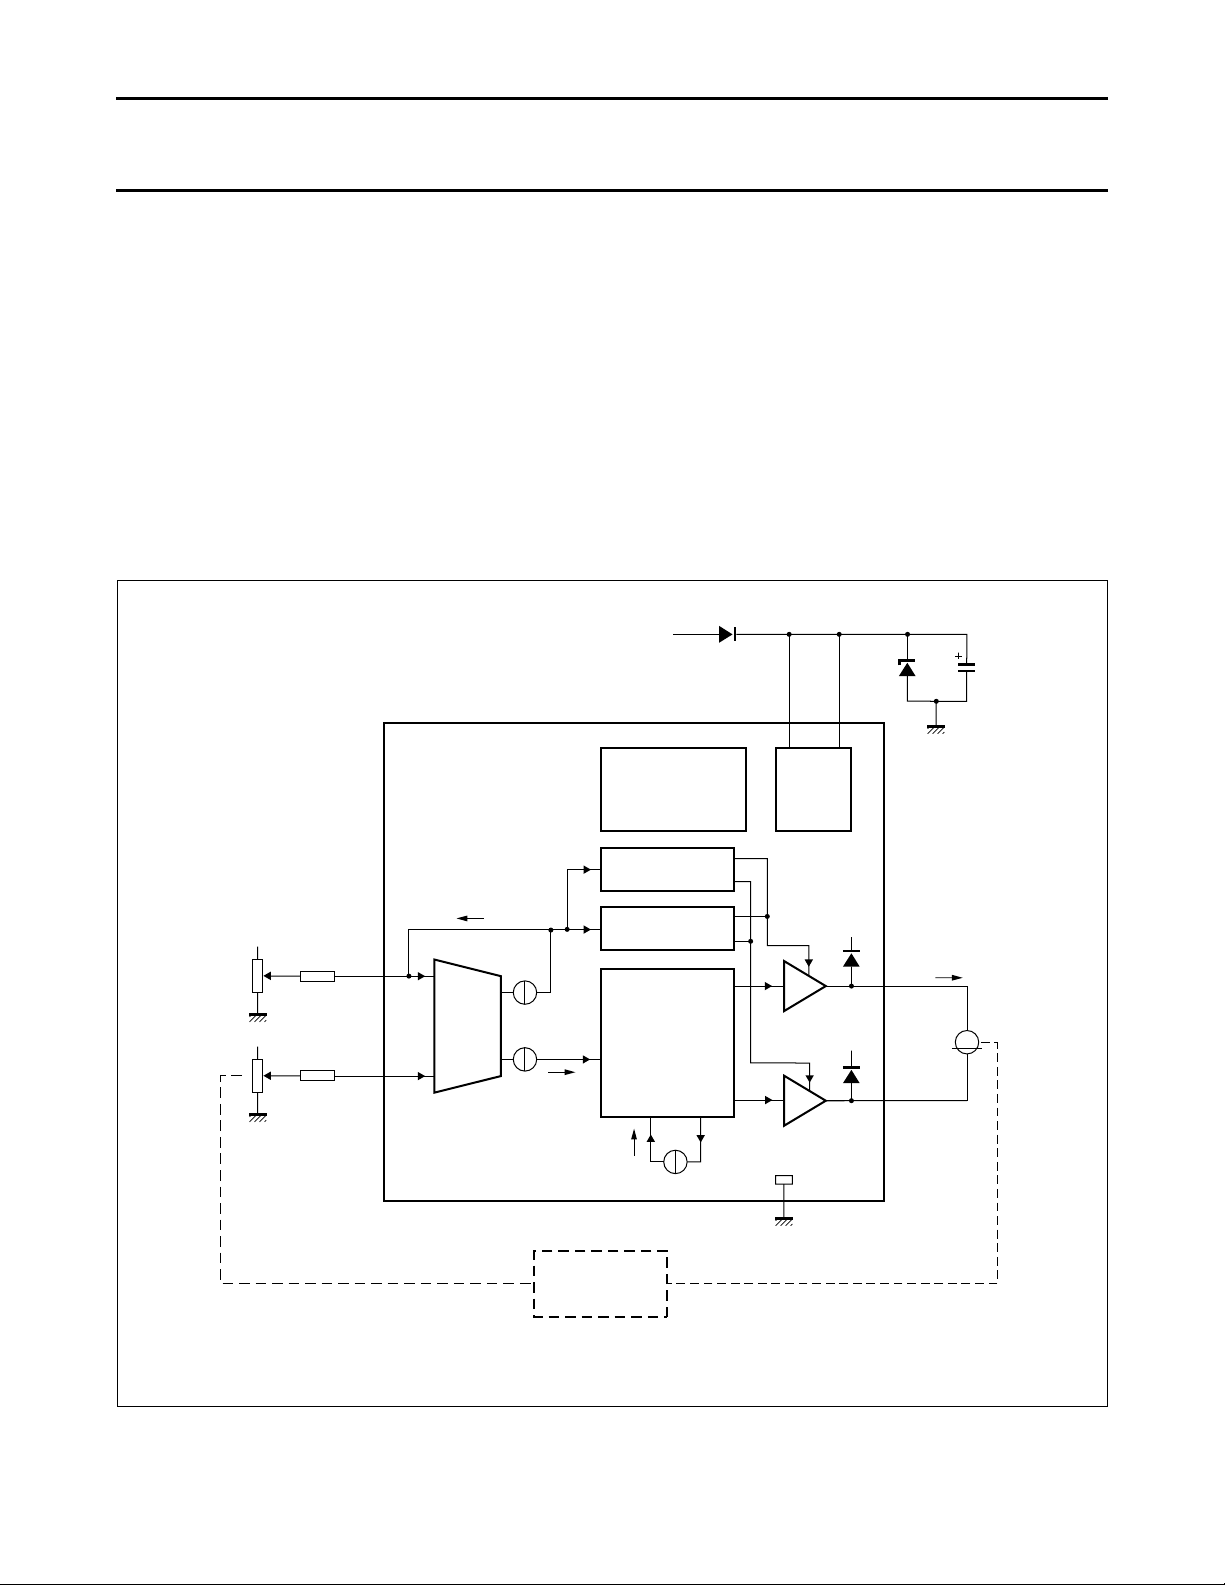
Fig.9 Best case application diagram.
handbook, full pagewidth
MGE640
INPUT
STAGE
SHORT-CIRCUIT
SUPPLY
BROKEN WIRE
PROTECTION
- OVER VOLTAGE
- UNDER VOLTAGE
- TEMPERATURE
WINDOWS
AND
COMPARATORS
V
P
V
P1
V
P2
V
P
OUT1
OUTPUT
STAGES
OUT2
SET
1 kΩ
2.2 kΩ
FB
I
SET
R
SET
R
FB
I
SET
TDA3629
+V
b
+V
b
+V
b
V
SET
+
−
V
FB
+
−
M
V
m
+
−
MECHANICAL
TRANSMISSION
43 V
47
µF
I
m
I
ref
Light position controller TDA3629
Application diagrams and additional information
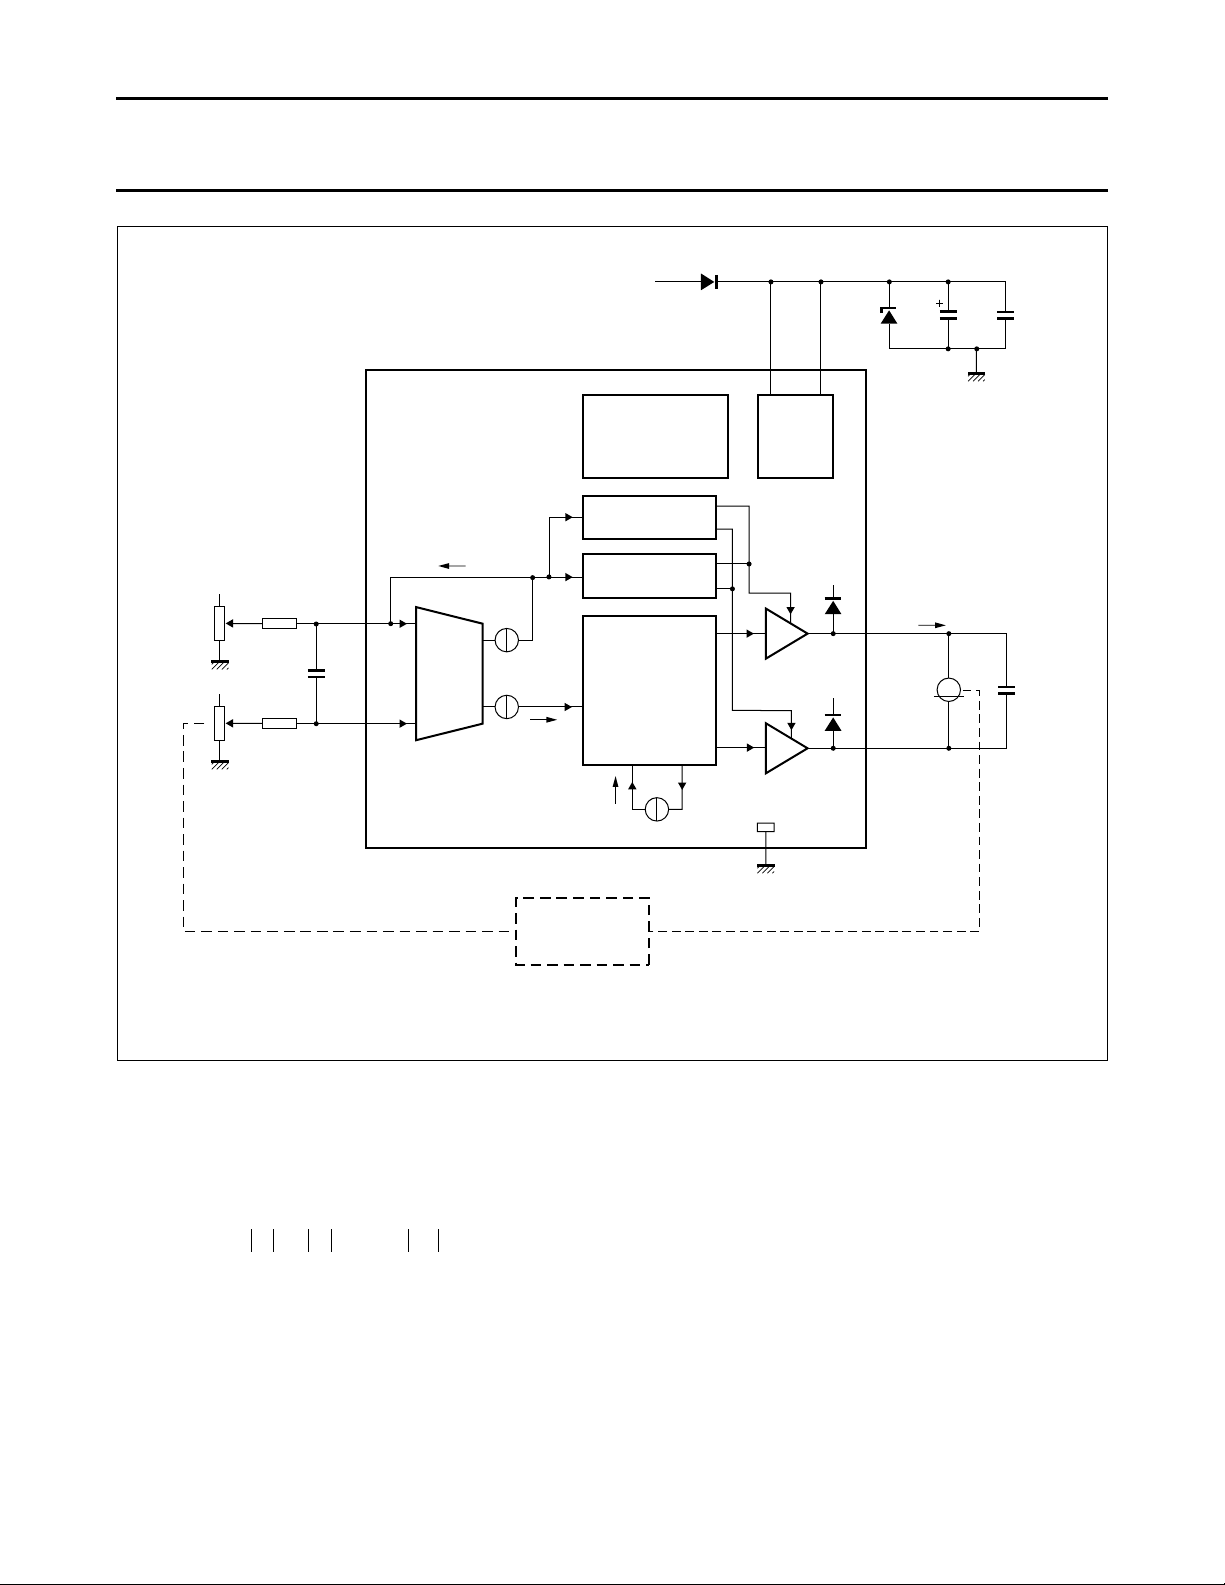
Two possible application diagrams are shown. The first
(see Fig.9) shows the best case: the lowest component
count. The second (see Fig.10) shows additional
components which may be necessary. Two capacitors are
added to meet EMC requirements (one on the VP pins, the
second one between the set and feedback input pins).
A third capacitor has been added across the motor to
suppress current spikes. The given values of these
capacitors have to be optimized by experiments carried
out on the total application. The resistors do not have to
have the same value. The voltage hysteresis is set by
means of R
SET
The resistor in the feedback input line (RFB) is present to
limit the current during the transients as illustrated in Figs 7
and 8. This resistor should have a value larger than 2 kΩ.
R
can be chosen freely but must also be larger than
SET
2 kΩ. A diode is placed in series with the supply line in both
applications to protect the device from reverse polarity
switching and from damage caused by pulses 1 and 3 in
Figs 7 and 8. In the present application a varistor is
included in the motor. The electrolytic capacitor of 47 µF
should have a very low ESR, for instance as low as 5 Ω at
a temperature of −40 °C. An extra ceramic capacitor
(approximately 100 nF) parallel to it is obligatory when this
.
can not be guaranteed.
1996 Sep 04 11
Page 12
Philips Semiconductors Product specification
Fig.10 Worst case application diagram.
handbook, full pagewidth
MGE641
INPUT
STAGE
SHORT-CIRCUIT
SUPPLY
BROKEN WIRE
PROTECTION
- OVER VOLTAGE
- UNDER VOLTAGE
- TEMPERATURE
WINDOWS
AND
COMPARATORS
V
P
V
P1
V
P2
V
P
OUT1
100
nF
OUTPUT
STAGES
OUT2
SET
100
nF
1 kΩ
2.2 kΩ
FB
I
SET
R
SET
R
FB
I
SET
TDA3629
+V
b
+V
b
+V
b
V
SET
+
−
V
FB
+
−
M
V
m
+
−
MECHANICAL
TRANSMISSION
43 V
47µF100
nF
I
m
I
ref
–( )× I
m
VPVm–( )×+=
Light position controller TDA3629
Thermal aspects
The dissipation of the device is the sum of two sources:
the supply current (IP− Im) times the supply voltage (VP)
plus the motor current (I
voltage (VP− Vm). In formula:
P V
(I
is not running. It is obvious from the ratings that the
combination of VP= 18 V, (IP− Im) = 80 mA,
Im = 900 mA and (VP− Vm) = 2.5 V can not be
allowed at T
note 2. But it is also improbable that the motor is
continuously driven, therefore the following assumptions
have been made.
− Im) is approximately equal to I
P
PIPIm
amb
) times the output saturation
m
= 105 °C; see chapter “Limiting values”
when the motor
P(ss)
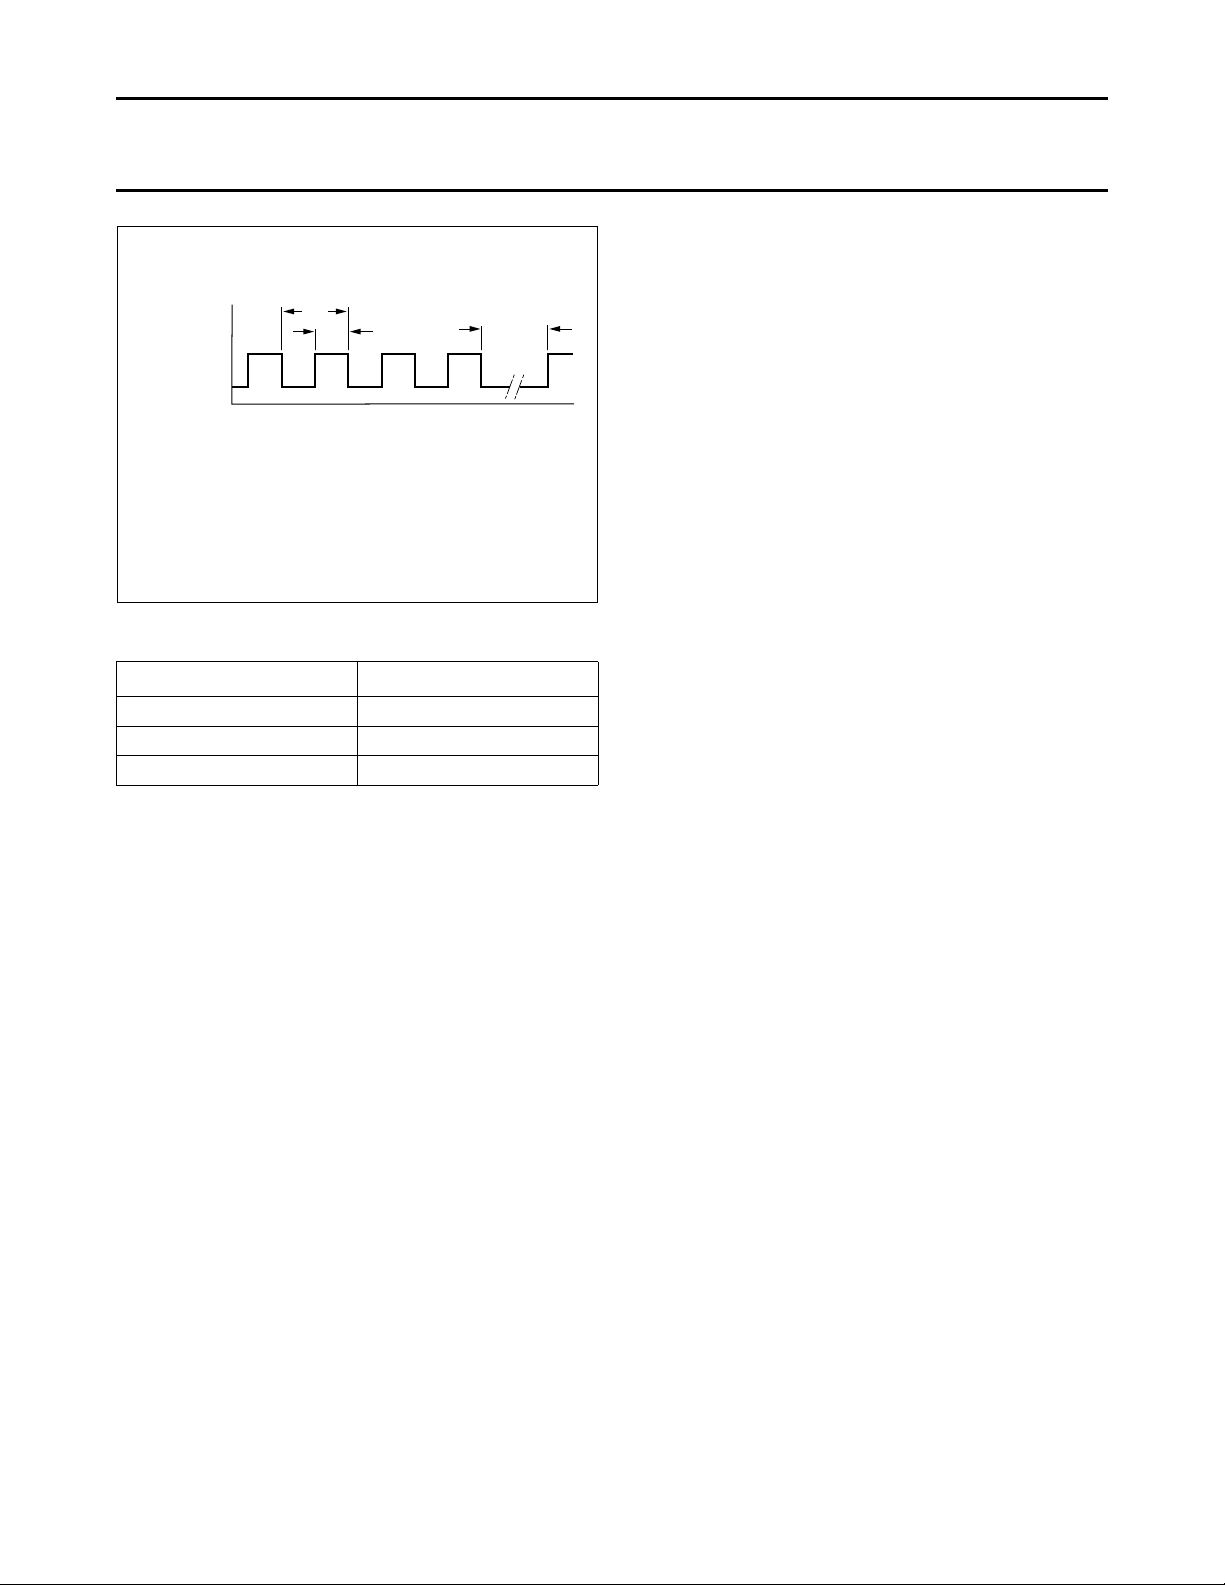
It is assumed that the device must be capable of moving
the motor from one end to the other in four equal steps and
that the total time needed for this excursion is 16 seconds.
After this excursion a pause is allowed before the same
pulses are used to return to the original position.
This operation is illustrated in Fig.11.
1996 Sep 04 12
Page 13
Philips Semiconductors Product specification
Fig.11 Thermal transient test.
The duration of the pause depends on the ambient temperature, see
Table 1.
handbook, halfpage
MGE642
active
motor
inactive
pause
8 s
4 s
time (s)
Light position controller TDA3629
Stereo operation
The default application will be when two modules are
driven by one set potentiometer. One module controls the
left head light, where the other one controls the right head
light. Each module is connected by three wires: the battery
line, the ground line and the set input wire. This can result
in two additional fault conditions: from one module the
battery line or the ground line can be broken, when the
other module is still connected. Assume that the left one
operates normally, where the right one has a fault. The
setting potentiometer will have extra loading when the
battery line is broken. This will result in a lower voltage at
the wiper of the setting potentiometer. Thus the left module
will start to regulate until a new equilibrium is reached.
The amount of extra loading can be influenced by the
external series resistor in the set input. These fault
Table 1 Duration of the pauses
T
(°C) PAUSE (s)
amb
<95 60
95 180
95 to 105 300
The maximum allowable dissipated power P is then
0.77 W during the motor active periods in the event of a
DIP8 package being used. Dissipation pulses due to
starting and stopping the motor can be ignored because of
their short duration. This maximum allowable dissipated
power implies that the maximum continuous motor current
(Im) is approximately 250 mA during the motor active
periods when the supply voltage VP is 13 V. The maximum
allowable dissipated power P is 0.67 W during the motor
active periods in the event of a SO16 package being used.
This implies that the maximum continuous motor current
(Im) is approximately 220 mA during the motor active
periods when the supply voltage (VP) is 13 V.
conditions and their implications should be considered
when the total application is designed.
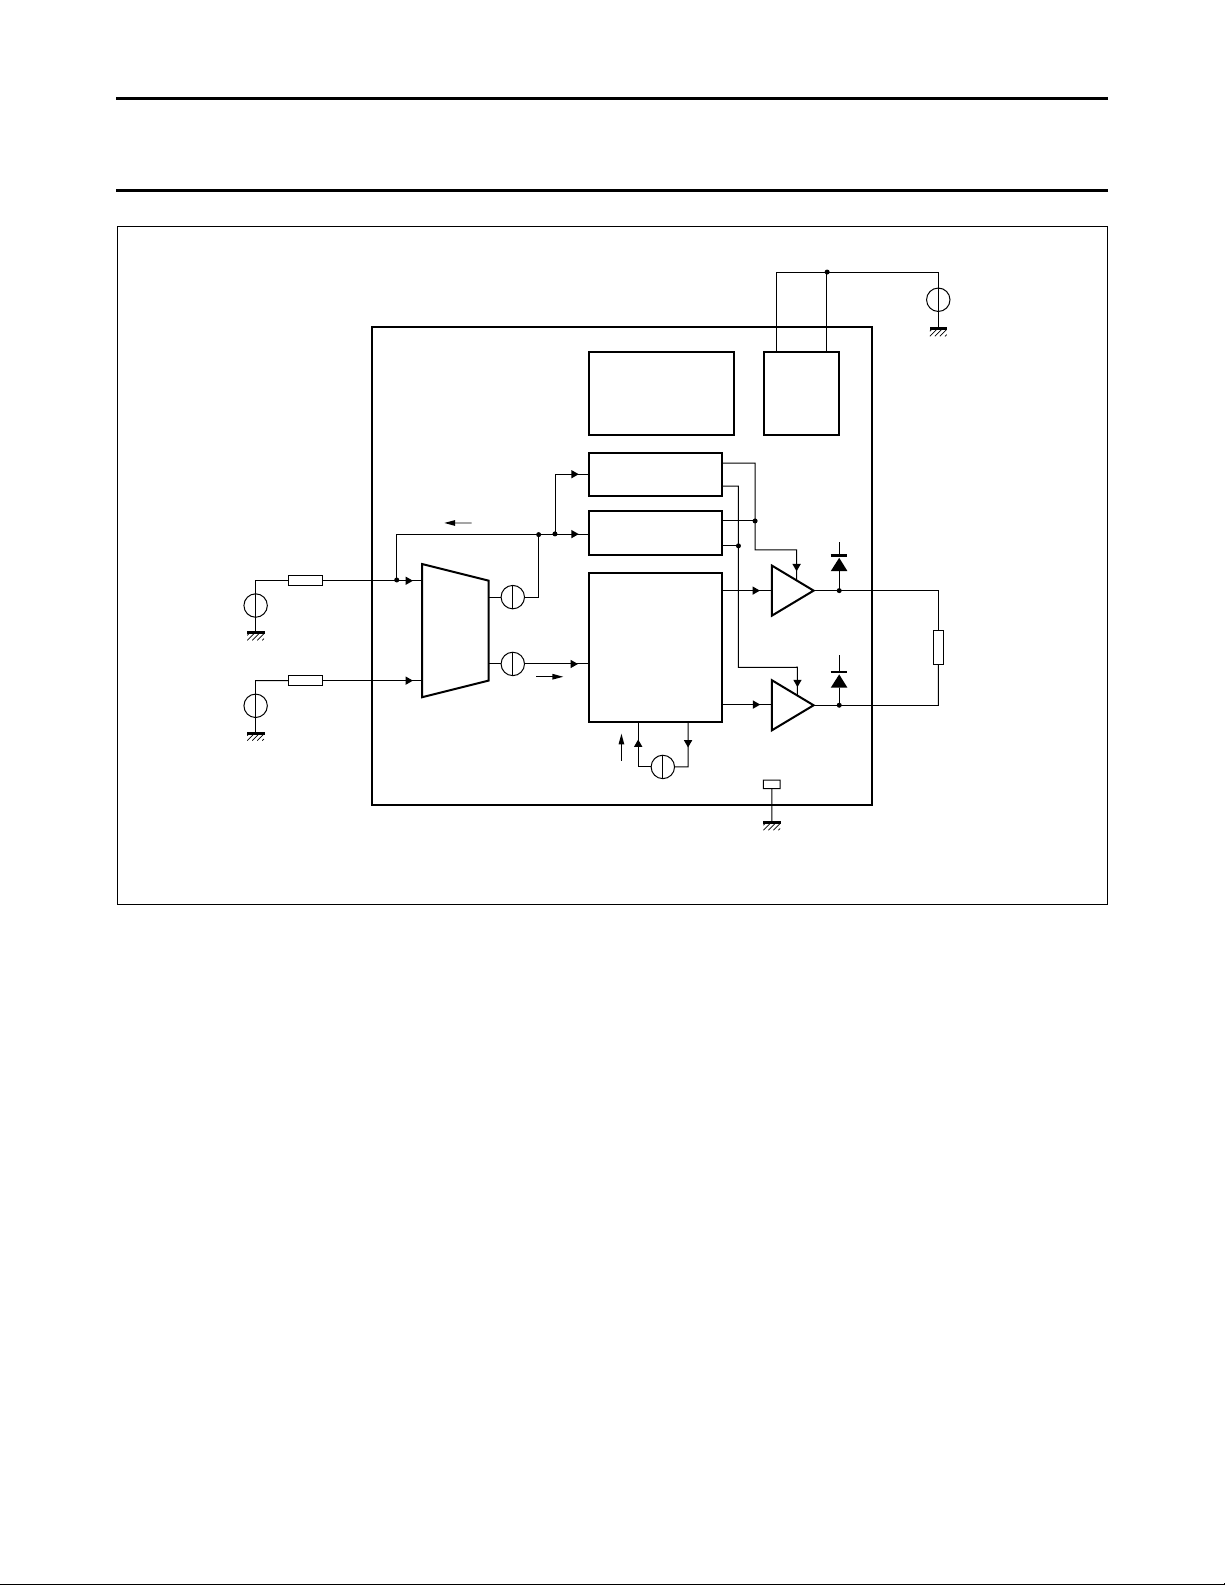
Test diagram
All parameters in chapter “Characteristics” until this
section are measured at T
= 25 °C and are tested at
amb
each device using the test set-up of Fig.12. The only
exceptions are parameters supply current (motor active)
and output voltage (motor output) where the 1 kΩ output
resistor is replaced by an appropriate current source.
1996 Sep 04 13
Page 14
Philips Semiconductors Product specification
Fig.12 Test set-up (general).
handbook, full pagewidth
MGE643
INPUT
STAGE
SHORT-CIRCUIT
SUPPLY
BROKEN WIRE
PROTECTION
- OVER VOLTAGE
- UNDER VOLTAGE
- TEMPERATURE
WINDOWS
AND
COMPARATORS
V
P
V
P1
V
P2
V
P
OUT1
1 kΩ
OUTPUT
STAGES
OUT2
SET
FB
I
SET
I
SET
V
FB
V
SET
RFB =
20 kΩ
R
SET
=
20 kΩ
TDA3629
+
−
+
−
+
−
12 V
I
ref
Light position controller TDA3629
1996 Sep 04 14
Page 15
Philips Semiconductors Product specification
Light position controller TDA3629
IMMUNITY TO NARROW BAND ELECTROMAGNETIC DISTURBANCES
Test procedure
GENERAL INFORMATION
The immunity is measured using a test procedure, which
is derived from the draft international standard
“ISO/DIS 11452”
, parts 1 and 7, submitted for circulation
1992 June 14.
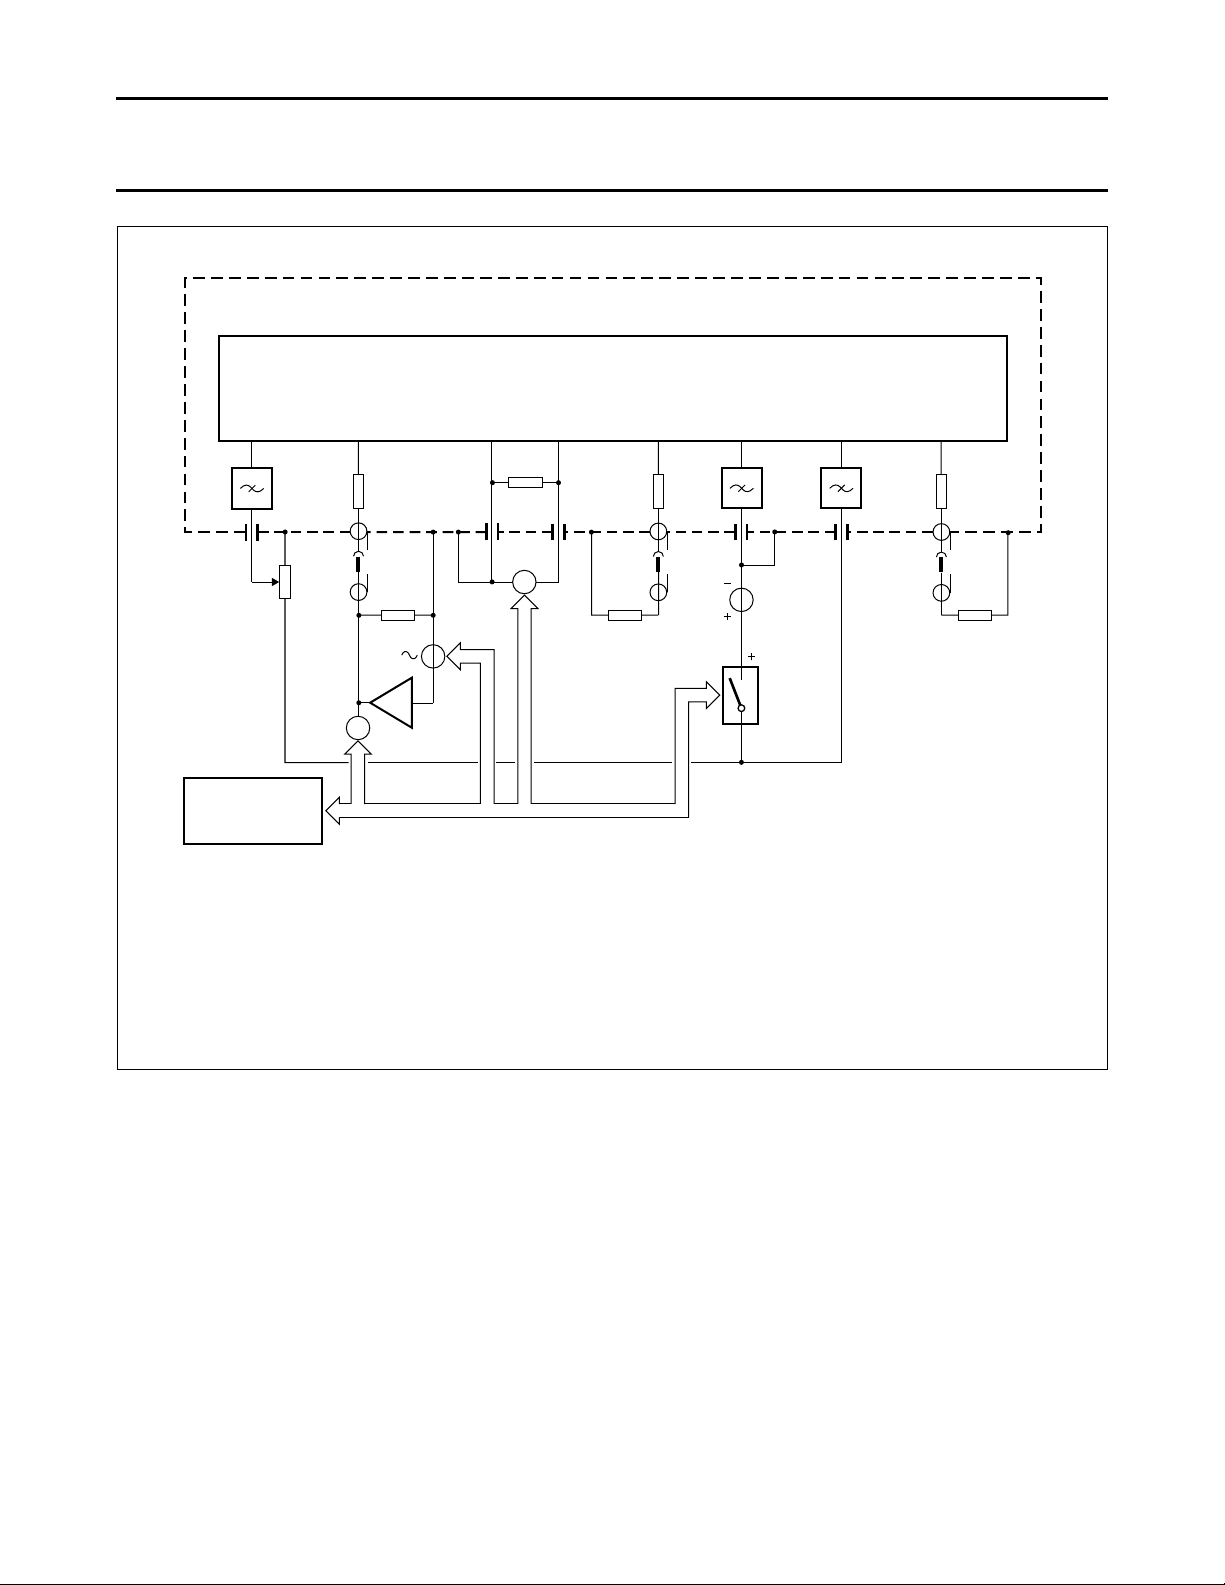
The test is carried out using a printed-circuit test board in
a test set-up, which is illustrated in Fig.13. The circuit
diagram of the test board is shown in Fig.14. The physical
layout of the test board is shown in Figs 15 to 17.
PREPARATION OF TEST
The IC under test is mounted onto the printed-circuit test
board. The printed-circuit test board is mounted into the
faraday cage (RF-shielded 19 inch-rack) and connected to
the test equipment as shown in Fig.13. One of three RF
voltage injection points has to be chosen for injection,
while the others have to be connected to passive
terminations. The injection into the control loop via input
RFC is shown in Fig.13.
After the set-up is completed, the feedback voltage is
selected by the appropriate setting of a jumper in the
jumper field J1 (see Fig.14) and the battery voltage is
switched on. With no RF voltage injected the correct
operation of the system is verified by turning the SET
potentiometer (see Fig.13) left and right (or vice-versa).
The outputs OUT1 and OUT2 will switch to on-state
(absolute differential voltage V
= 3 to 5 V DC) in both
diff
turn directions. If the device under test functions correctly,
the potentiometer is set to a position where the absolute
voltage difference between the slider connection of the
potentiometer and the jumper J1 is less than 5 mV.
After adjustment, the absolute differential output voltage
V
has to be below 100 mV. Having reached this
diff
condition the immunity test may be started.
has to be verified, because the level setting may have an
overshoot and the device under test may have a latching
behaviour. The verification is achieved by switching off the
power supply for 1 s after degradation is first detected.
Then the supply is switched on and the degradation is
rechecked. If the second check also indicates a
degradation, then the values of RF level and frequency are
inserted into a data file for reporting. If the second check is
negative the level is further increased.
If no degradation occurs until the specified maximum test
level is reached, the maximum level is recorded together
with the frequency of that step.
R
ECOMMENDED RF-VOLTAGE SETTING PROCEDURE
For a fast setting of the RF voltage to the required test level
step it is recommended that the substitution method is
used.
This method sets the actual test level with respect to level
values that have been filed in a pre-measurement.
The RF source in the test set-up is built from a low-power
RF generator and suitable amplifiers. In the recommended
pre-measurement the RF voltage at the injection point is
measured, while the signal generator outputs a constant
voltage level (e.g. 100 mV). Thus, the gain factor from the
output of the RF generator to the injection point can be
easily calculated.
In the pre-measurement the RF voltage at the injection
point is measured for each frequency step. Dividing this
measured voltage by 100 mV results in the gain factor for
this frequency. All gain factors together with their
frequency value are filed for use in the level setting of the
immunity tests.
In the immunity test routine, a required RF voltage test
level at a frequency step is obtained by setting the RF
signal generator to a level that is calculated by dividing the
required RF voltage test level by the gain factor of that
frequency.
Test conditions
TEST OF IMMUNITY
For the test of immunity the RF voltage is injected into the
test board and V
is monitored for degradation. V
diff
diff
is
degraded if its actual value exceeds the maximum value
described in Table 2. In the test routine the frequency is
varied in steps from the start frequency to the stop
frequency (see Table 2). Within each frequency step the
level of injected RF voltage is incremented by steps to the
maximum test level, which is specified in Table 2.
Each step level is held constant for the dwell time. After the
dwell time has elapsed, the degradation of the absolute
output voltage is checked. If a degradation is detected it
1996 Sep 04 15
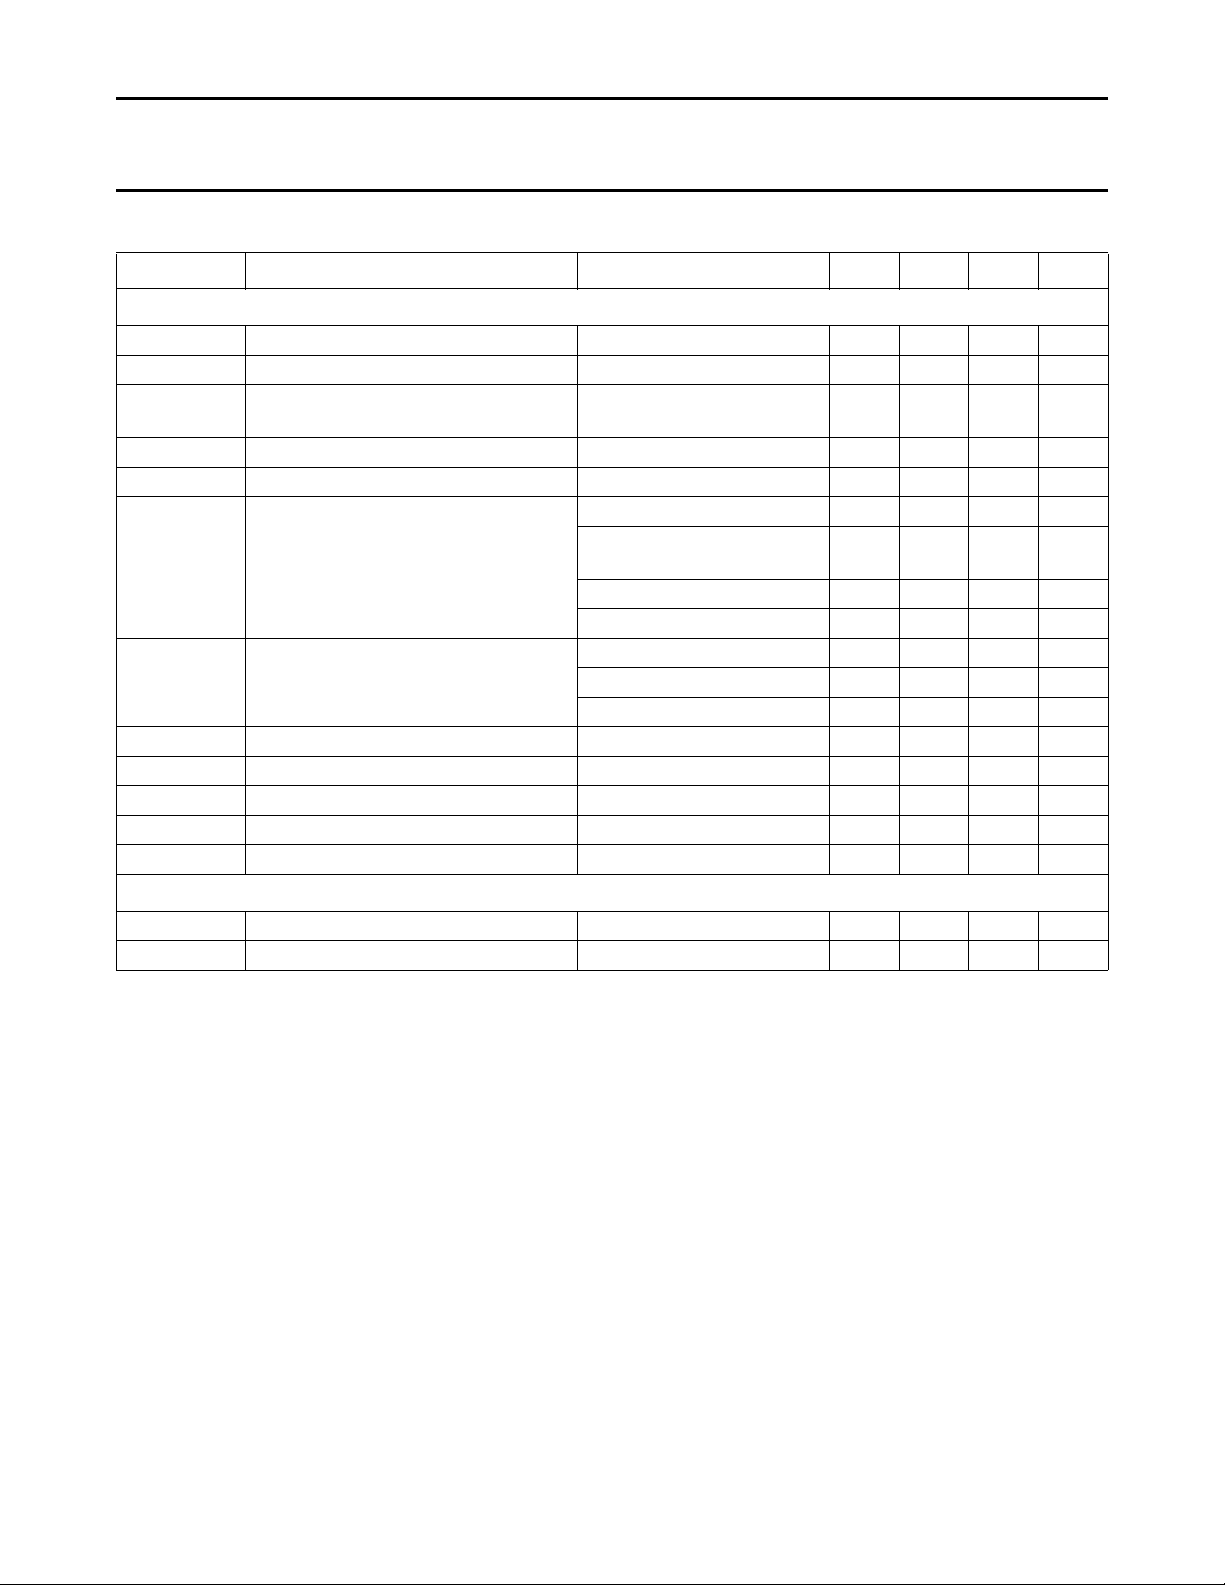
The test is carried out using the test procedure as
mentioned before and under the conditions mentioned in
Table 2.
Page 16
Philips Semiconductors Product specification
--
×
Light position controller TDA3629
Table 2 General test conditions for immunity measurements
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
General
T
amb
V
bat
V
diff
ambient temperature 18 − 28
battery voltage 12.5 − 13.5 V
absolute differential output voltage
(DC value)
f
start
f
stop
f
n
V
IL(rms)
V
TL(max)
V
START(rms)
V
STEP(rms)
Q
TL
t
dwell
start frequency − 250 − kHz
stop frequency − 1000 − MHz
frequency steps from 250 kHz to 1 MHz − − 100 kHz
immunity voltage level (RMS value) from 250 kHz to 1 MHz 5 − − V
maximum test voltage level − 24 − V
voltage start level (RMS value) 2 4 6 V
voltage level step (RMS value) − 2 − V
relative accuracy of test level −10 − +10 %
dwell time 2 − − s
RF-voltage characteristic; note 2
f
M(AM)
m
D
AM modulation frequency constant peak level − 1 − kHz
modulation depth constant peak level − 0 − %
0 1.0 V
from 1 to 10 MHz; 9 steps
− note 1 − MHz
(logarithmic): n = 0 to 8
from 10 to 200 MHz − − 2 MHz
from 200 to 1000 MHz − − 20 MHz
from 1 MHz to 5 MHz 10 − − V
from 5 MHz to 1 GHz 15 − − V
o
C
Notes
n
-
1. The typical value is
2. For definition see
“ISO/DIS 11452-1”
1 10
9
, annex B.
1996 Sep 04 16
Page 17
Philips Semiconductors Product specification
Fig.13 Test set-up for immunity test.
RFC is the RF voltage injection point to control path.
RFG is the RF voltage injection point to ground.
RFS is the RF voltage injection point to battery voltage (+13 V).
For all decoupling filters Z >> 150 Ω.
handbook, full pagewidth
MGE853
100 Ω
620 Ω
100 Ω
50 Ω
50 Ω
50 Ω
1 kΩ
100 Ω
CONTROL
RFC
OUT1 OUT2
RFG
GND
+13 V
RFS
V
V
TEST CONTROL
AND
DATA AQUISITION
V
bat
V
diff
+−
RF
digital
50
nF
50
nF
50
nF
50
nF
50
nF
RF
RF
digital
SET
LIGHT POSITION CONTROL
IMMUNITY TEST BOARD
FARADAY CAGE
Light position controller TDA3629
1996 Sep 04 17
Page 18
Philips Semiconductors Product specification
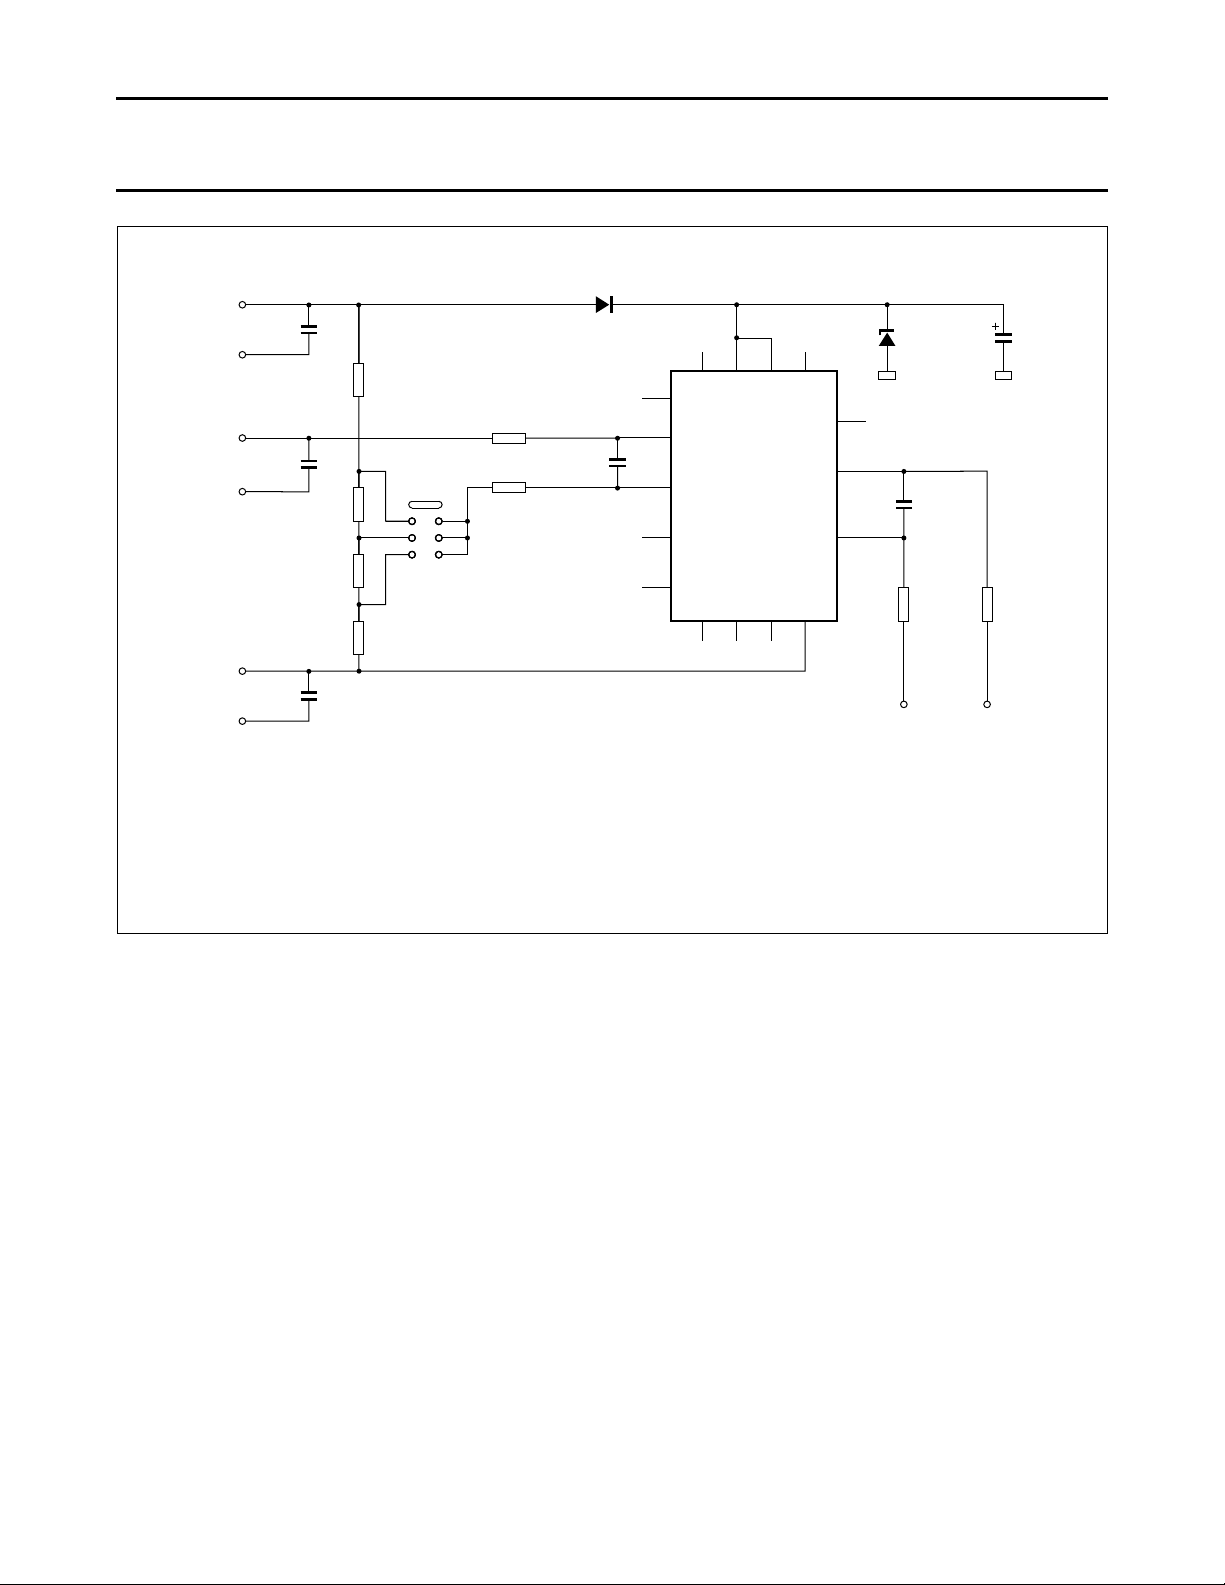
Fig.14 Circuit diagram of the test board.
Feedback voltage setting J1: amount of voltage difference between J1 and SET input adjusted by potentiometer setting to <50 mV (see also Fig.13).
handbook, full pagewidth
C2
47 nF
+13 V
RFS
C3
47 nF
C1
100 nF
CONTROL
RFC
C4
47 nF
GND
RFG
R4
1.2 kΩ
R5
820 Ω
R9
510 Ω
R8
510 Ω
R6
820 Ω
R7
1.2 kΩ
20 kΩ
15 kΩ
R2
R1
FB
SET
FB
SET
n.c.
1
16
2
n.c.
10
IC1
TDA3629T
n.c.
3
n.c.
4
V
P1
V
bat
5
D1
1N4005
J1
1
V
P2
12
n.c.
15
n.c.7n.c.8n.c.13GND
9
C5
1.0 nF
D2
BZT03/C43
C6
47 µF
(50 V)
OUT2
OUT1
OUT2
OUT1
OUT2
OUT1
11
6
n.c.
14
MGE852
Light position controller TDA3629
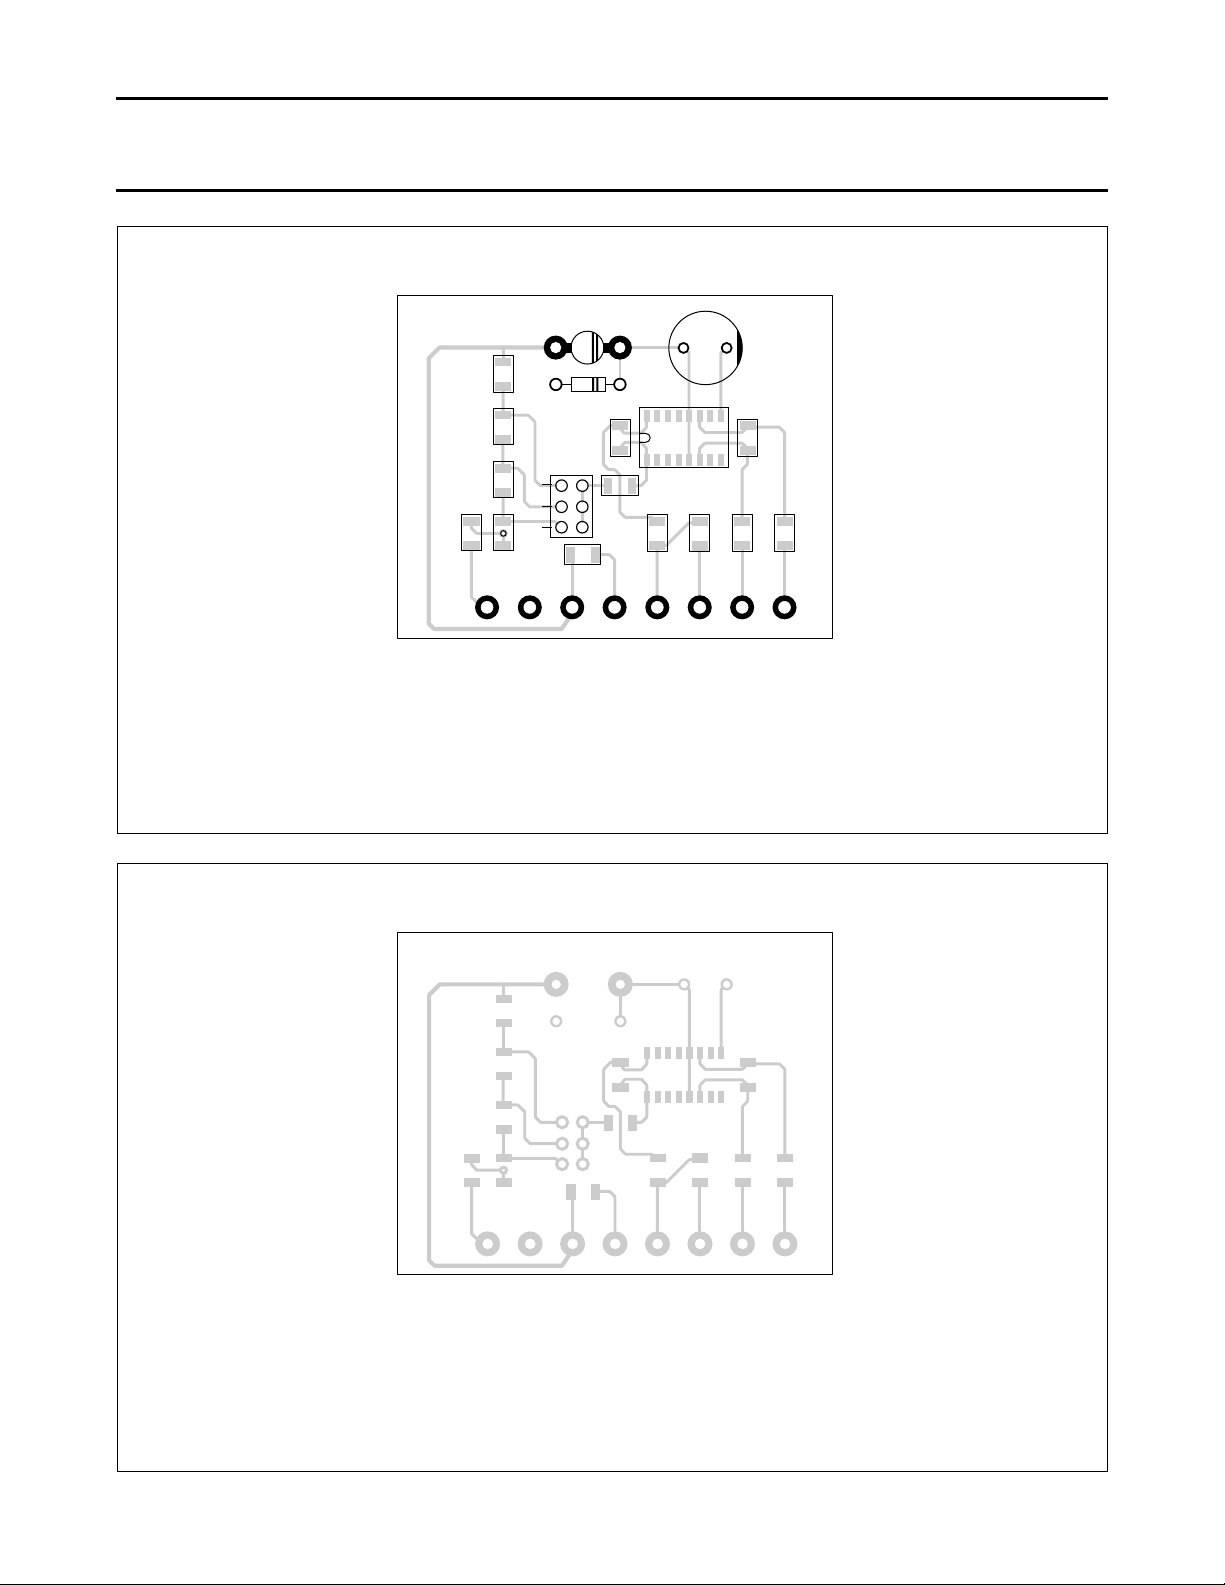
Figs 15 to 17 show the layout of the immunity test board used for the evaluation.
1996 Sep 04 18
Page 19
Philips Semiconductors Product specification
Fig.15 Component placement of the printed-circuit board.
handbook, full pagewidth
MGE854
R1
R2
R7
R6
R5
R4
C4
C3
C5
C6
C1
IC1
D2
D1
C2
RFG
GND
+13 V
RFS
CONTROL
RFC
OUT1
OUT2
70%5030
J1
R9 R8
Fig.16 Top view of printed-circuit board.
handbook, full pagewidth
MGE855
Light position controller TDA3629
1996 Sep 04 19
Page 20
Philips Semiconductors Product specification
Fig.17 Bottom view of printed-circuit board.
handbook, full pagewidth
MGE856
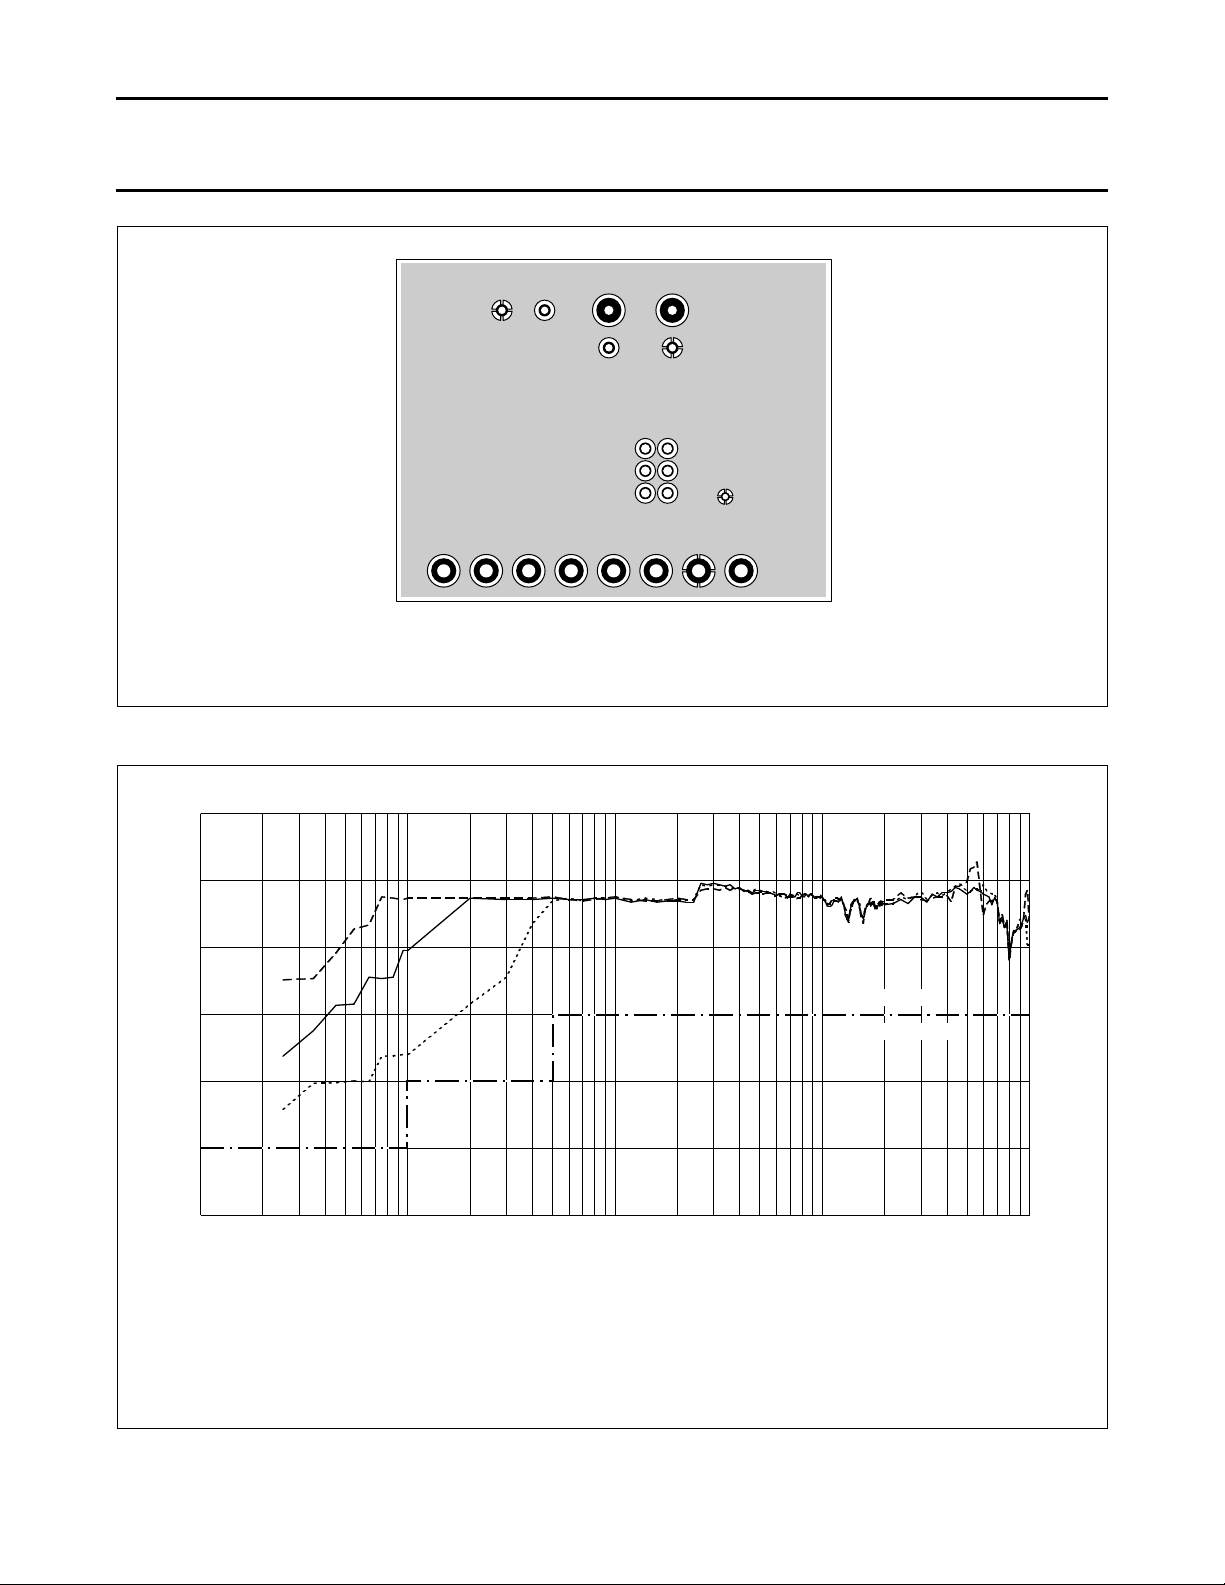
Fig.18 Typical immunity results with respect to setting of jumper 1 (30, 50 and 70%) RF input to RFC.
(1) Feedback voltage is 30%.
(2) Feedback voltage is 50%.
(3) Feedback voltage is 70%.
(4) Immunity level.
handbook, full pagewidth
0
30
V
RF(rms)
(V)
10
2
10
3
MGE858
10
(1)
(2)
(3)
(4)
frequency (MHz)
110
−1
10
20
device accepted
device not accepted
Light position controller TDA3629
Test results
1996 Sep 04 20
Page 21
Philips Semiconductors Product specification
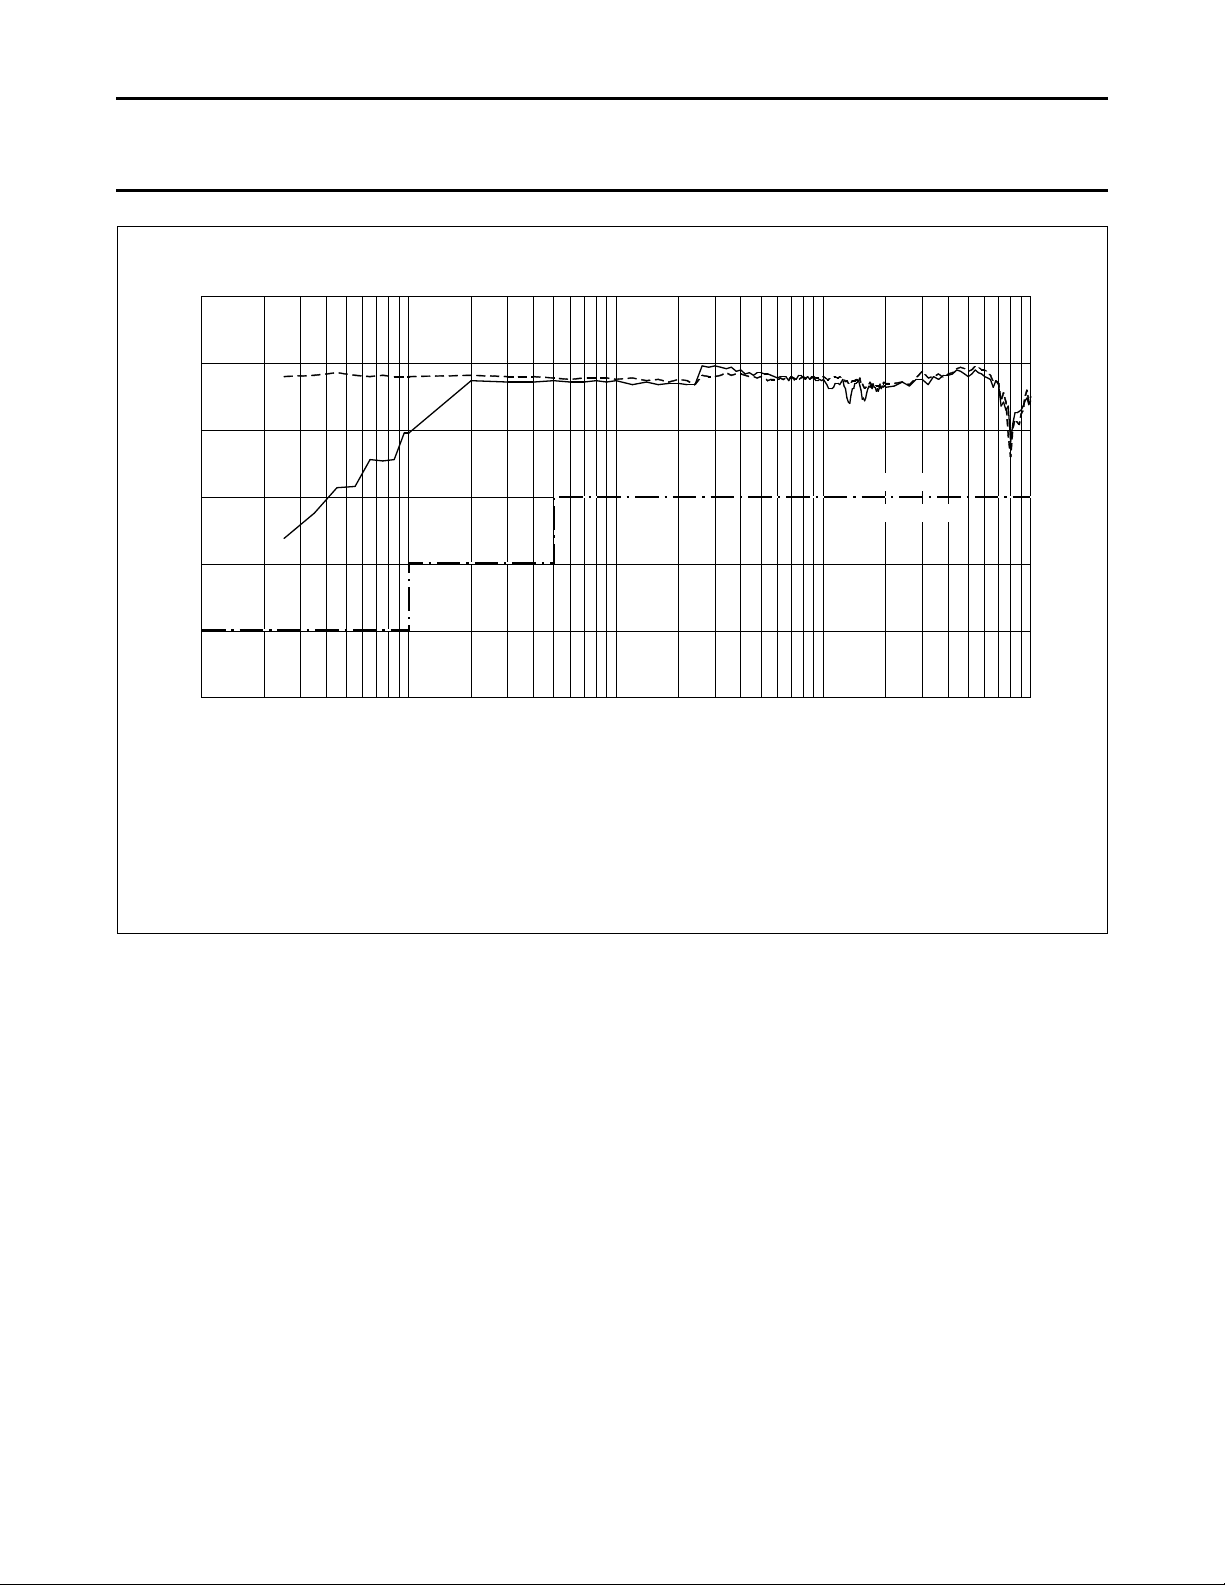
Fig.19 Typical immunity results with respect to RF injection points, with jumper 1 set to 50%.
(1) RF voltage injection point to ground and to battery voltage.
(2) RF voltage injection point to control path.
(3) Immunity level.
handbook, full pagewidth
0
30
V
RF(rms)
(V)
10
2
10
3
MGE857
10
frequency (MHz)
110
−1
10
20
device accepted
device not accepted
(1)
(2)
(3)
Light position controller TDA3629
The typical immunity results of the TDA3629T are shown in Fig.18. The RF voltage was injected into the control line
(see also Figs 13 and 14). This injection point is the most sensitive one that could be found. This is underlined by the
comparison results shown in Fig.19.
1996 Sep 04 21
Page 22
Philips Semiconductors Product specification
REFERENCES
OUTLINE
VERSION
EUROPEAN
PROJECTION
ISSUE DATE
IEC JEDEC EIAJ
SOT97-1
92-11-17
95-02-04
UNIT
A
max.
1 2
b
1
(1) (1)
(1)
b
2
c D E e M
Z
H
L
mm
DIMENSIONS (inch dimensions are derived from the original mm dimensions)
A
min.
A
max.
b
max.
w
M
E
e
1
1.73
1.14
0.53
0.38
0.36
0.23
9.8
9.2
6.48
6.20
3.60
3.05
0.2542.54 7.62
8.25
7.80
10.0
8.3
1.154.2 0.51 3.2
inches
0.068
0.045
0.021
0.015
0.014
0.009
1.07
0.89
0.042
0.035
0.39
0.36
0.26
0.24
0.14
0.12
0.010.10 0.30
0.32
0.31
0.39
0.33
0.0450.17 0.020 0.13
b
2
050G01 MO-001AN
M
H
c
(e )
1
M
E
A
L
seating plane
A
1
w M
b
1
e
D
A
2
Z
8
1
5
4
b
E
0 5 10 mm
scale
Note
1. Plastic or metal protrusions of 0.25 mm maximum per side are not included.
pin 1 index
DIP8: plastic dual in-line package; 8 leads (300 mil)
SOT97-1
Light position controller TDA3629
PACKAGE OUTLINES
1996 Sep 04 22
Page 23
Philips Semiconductors Product specification
X
w M
θ
A
A
1
A
2
b
p
D
H
E
L
p
Q
detail X
E
Z
e
c
L
v M
A
(A )
3
A
8
9
1
16
y
pin 1 index
UNIT
A
max.
A1A
2
A
3
b
p
c D
(1)E(1) (1)
e H
E
L L
p
Q Zywv θ
REFERENCES
OUTLINE
VERSION
EUROPEAN
PROJECTION
ISSUE DATE
IEC JEDEC EIAJ
mm
inches
1.75
0.25
0.10
1.45
1.25
0.25
0.49
0.36
0.25
0.19
10.0
9.8
4.0
3.8
1.27
6.2
5.8
0.7
0.6
0.7
0.3
8
0
o
o
0.25 0.1
DIMENSIONS (inch dimensions are derived from the original mm dimensions)
Note
1. Plastic or metal protrusions of 0.15 mm maximum per side are not included.
1.0
0.4
SOT109-1
91-08-13
95-01-23
076E07S MS-012AC
0.069
0.0098
0.0039
0.057
0.049
0.01
0.019
0.014
0.0098
0.0075
0.39
0.38
0.16
0.15
0.050
1.05
0.041
0.24
0.23
0.028
0.020
0.028
0.012
0.01
0.25
0.01 0.004
0.039
0.016
0 2.5 5 mm
scale
SO16: plastic small outline package; 16 leads; body width 3.9 mm
SOT109-1
Light position controller TDA3629
1996 Sep 04 23
Page 24
Philips Semiconductors Product specification
Light position controller TDA3629
SOLDERING
Introduction
There is no soldering method that is ideal for all IC
packages. Wave soldering is often preferred when
through-hole and surface mounted components are mixed
on one printed-circuit board. However, wave soldering is
not always suitable for surface mounted ICs, or for
printed-circuits with high population densities. In these
situations reflow soldering is often used.
This text gives a very brief insight to a complex technology.
A more in-depth account of soldering ICs can be found in
our
“IC Package Databook”
(order code 9398 652 90011).
DIP
SOLDERING BY DIPPING OR BY WAVE
The maximum permissible temperature of the solder is
260 °C; solder at this temperature must not be in contact
with the joint for more than 5 seconds. The total contact
time of successive solder waves must not exceed
5 seconds.
The device may be mounted up to the seating plane, but
the temperature of the plastic body must not exceed the
specified maximum storage temperature (T
stg max
). If the
printed-circuit board has been pre-heated, forced cooling
may be necessary immediately after soldering to keep the
temperature within the permissible limit.
EPAIRING SOLDERED JOINTS
R
Apply a low voltage soldering iron (less than 24 V) to the
lead(s) of the package, below the seating plane or not
more than 2 mm above it. If the temperature of the
soldering iron bit is less than 300 °C it may remain in
contact for up to 10 seconds. If the bit temperature is
between 300 and 400 °C, contact may be up to 5 seconds.
SO
REFLOW SOLDERING
Reflow soldering techniques are suitable for all SO
packages.
Several techniques exist for reflowing; for example,
thermal conduction by heated belt. Dwell times vary
between 50 and 300 seconds depending on heating
method. Typical reflow temperatures range from
215 to 250 °C.
Preheating is necessary to dry the paste and evaporate
the binding agent. Preheating duration: 45 minutes at
45 °C.
W
AVE SOLDERING
Wave soldering techniques can be used for all SO
packages if the following conditions are observed:
• A double-wave (a turbulent wave with high upward
pressure followed by a smooth laminar wave) soldering
technique should be used.
• The longitudinal axis of the package footprint must be
parallel to the solder flow.
• The package footprint must incorporate solder thieves at
the downstream end.
During placement and before soldering, the package must
be fixed with a droplet of adhesive. The adhesive can be
applied by screen printing, pin transfer or syringe
dispensing. The package can be soldered after the
adhesive is cured.
Maximum permissible solder temperature is 260 °C, and
maximum duration of package immersion in solder is
10 seconds, if cooled to less than 150 °C within
6 seconds. Typical dwell time is 4 seconds at 250 °C.
A mildly-activated flux will eliminate the need for removal
of corrosive residues in most applications.
REPAIRING SOLDERED JOINTS
Fix the component by first soldering two diagonally-
opposite end leads. Use only a low voltage soldering iron
(less than 24 V) applied to the flat part of the lead. Contact
time must be limited to 10 seconds at up to 300 °C. When
using a dedicated tool, all other leads can be soldered in
one operation within 2 to 5 seconds between
270 and 320 °C.
Reflow soldering requires solder paste (a suspension of
fine solder particles, flux and binding agent) to be applied
to the printed-circuit board by screen printing, stencilling or
pressure-syringe dispensing before package placement.
1996 Sep 04 24
Page 25
Philips Semiconductors Product specification
Light position controller TDA3629
DEFINITIONS
Data sheet status
Objective specification This data sheet contains target or goal specifications for product development.
Preliminary specification This data sheet contains preliminary data; supplementary data may be published later.
Product specification This data sheet contains final product specifications.
Limiting values
Limiting values given are in accordance with the Absolute Maximum Rating System (IEC 134). Stress above one or
more of the limiting values may cause permanent damage to the device. These are stress ratings only and operation
of the device at these or at any other conditions above those given in the Characteristics sections of the specification
is not implied. Exposure to limiting values for extended periods may affect device reliability.
Application information
Where application information is given, it is advisory and does not form part of the specification.
LIFE SUPPORT APPLICATIONS
These products are not designed for use in life support appliances, devices, or systems where malfunction of these
products can reasonably be expected to result in personal injury. Philips customers using or selling these products for
use in such applications do so at their own risk and agree to fully indemnify Philips for any damages resulting from such
improper use or sale.
1996 Sep 04 25
Page 26
Philips Semiconductors Product specification
Light position controller TDA3629
NOTES
1996 Sep 04 26
Page 27
Philips Semiconductors Product specification
Light position controller TDA3629
NOTES
1996 Sep 04 27
Page 28
Philips Semiconductors – a worldwide company
Argentina: see South America
Australia: 34 Waterloo Road, NORTH RYDE, NSW 2113,
Tel. +61 2 9805 4455, Fax. +61 2 9805 4466
Austria: Computerstr. 6, A-1101 WIEN, P.O. Box 213,
Tel. +43 1 60 101, Fax. +43 1 60 101 1210
Belarus: Hotel Minsk Business Center, Bld. 3, r. 1211, Volodarski Str. 6,
220050 MINSK, Tel. +375 172 200 733, Fax. +375 172 200 773
Belgium: see The Netherlands
Brazil: see South America
Bulgaria: Philips Bulgaria Ltd., Energoproject, 15th floor,
51 James Bourchier Blvd., 1407 SOFIA,
Tel. +359 2 689 211, Fax. +359 2 689 102
Canada: PHILIPS SEMICONDUCTORS/COMPONENTS,
Tel. +1 800 234 7381
China/Hong Kong: 501 Hong Kong Industrial Technology Centre,
72 Tat Chee Avenue, Kowloon Tong, HONG KONG,
Tel. +852 2319 7888, Fax. +852 2319 7700
Colombia: see South America
Czech Republic: see Austria
Denmark: Prags Boulevard 80, PB 1919, DK-2300 COPENHAGEN S,
Tel. +45 32 88 2636, Fax. +45 31 57 1949
Finland: Sinikalliontie 3, FIN-02630 ESPOO,
Tel. +358 615 800, Fax. +358 615 80920
France: 4 Rue du Port-aux-Vins, BP317, 92156 SURESNES Cedex,
Tel. +33 1 40 99 6161, Fax. +33 1 40 99 6427
Germany: Hammerbrookstraße 69, D-20097 HAMBURG,
Tel. +49 40 23 53 60, Fax. +49 40 23 536 300
Greece: No. 15, 25th March Street, GR 17778 TAVROS,
Tel. +30 1 4894 339/911, Fax. +30 1 4814 240
Hungary: see Austria
India: Philips INDIA Ltd, Shivsagar Estate, A Block, Dr. Annie Besant Rd.
Worli, MUMBAI 400 018, Tel. +91 22 4938 541, Fax. +91 22 4938 722
Indonesia: see Singapore
Ireland: Newstead, Clonskeagh, DUBLIN 14,
Tel. +353 1 7640 000, Fax. +353 1 7640 200
Israel: RAPAC Electronics, 7 Kehilat Saloniki St, TEL AVIV 61180,
Tel. +972 3 645 0444, Fax. +972 3 649 1007
Italy: PHILIPS SEMICONDUCTORS, Piazza IV Novembre 3,
20124 MILANO, Tel. +39 2 6752 2531, Fax. +39 2 6752 2557
Japan: Philips Bldg 13-37, Kohnan 2-chome, Minato-ku, TOKYO 108,
Tel. +81 3 3740 5130, Fax. +81 3 3740 5077
Korea: Philips House, 260-199 Itaewon-dong, Yongsan-ku, SEOUL,
Tel. +82 2 709 1412, Fax. +82 2 709 1415
Malaysia: No. 76 Jalan Universiti, 46200 PETALING JAYA, SELANGOR,
Tel. +60 3 750 5214, Fax. +60 3 757 4880
Mexico: 5900 Gateway East, Suite 200, EL PASO, TEXAS 79905,
Tel. +9-5 800 234 7381
Middle East: see Italy
Netherlands: Postbus 90050, 5600 PB EINDHOVEN, Bldg. VB,
Tel. +31 40 27 82785, Fax. +31 40 27 88399
New Zealand: 2 Wagener Place, C.P.O. Box 1041, AUCKLAND,
Tel. +64 9 849 4160, Fax. +64 9 849 7811
Norway: Box 1, Manglerud 0612, OSLO,
Tel. +47 22 74 8000, Fax. +47 22 74 8341
Philippines: Philips Semiconductors Philippines Inc.,
106 Valero St. Salcedo Village, P.O. Box 2108 MCC, MAKATI,
Metro MANILA, Tel. +63 2 816 6380, Fax. +63 2 817 3474
Poland: Ul. Lukiska 10, PL 04-123 WARSZAWA,
Tel. +48 22 612 2831, Fax. +48 22 612 2327
Portugal: see Spain
Romania: see Italy
Russia: Philips Russia, Ul. Usatcheva 35A, 119048 MOSCOW,
Tel. +7 095 926 5361, Fax. +7 095 564 8323
Singapore: Lorong 1, Toa Payoh, SINGAPORE 1231,
Tel. +65 350 2538, Fax. +65 251 6500
Slovakia: see Austria
Slovenia: see Italy
South Africa: S.A. PHILIPS Pty Ltd., 195-215 Main Road Martindale,
2092 JOHANNESBURG, P.O. Box 7430 Johannesburg 2000,
Tel. +27 11 470 5911, Fax. +27 11 470 5494
South America: Rua do Rocio 220, 5th floor, Suite 51,
04552-903 São Paulo, SÃO PAULO - SP, Brazil,
Tel. +55 11 821 2333, Fax. +55 11 829 1849
Spain: Balmes 22, 08007 BARCELONA,
Tel. +34 3 301 6312, Fax. +34 3 301 4107
Sweden: Kottbygatan 7, Akalla, S-16485 STOCKHOLM,
Tel. +46 8 632 2000, Fax. +46 8 632 2745
Switzerland: Allmendstrasse 140, CH-8027 ZÜRICH,
Tel. +41 1 488 2686, Fax. +41 1 481 7730
Taiwan: PHILIPS TAIWAN Ltd., 23-30F, 66,
Chung Hsiao West Road, Sec. 1, P.O. Box 22978,
TAIPEI 100, Tel. +886 2 382 4443, Fax. +886 2 382 4444
Thailand: PHILIPS ELECTRONICS (THAILAND) Ltd.,
209/2 Sanpavuth-Bangna Road Prakanong, BANGKOK 10260,
Tel. +66 2 745 4090, Fax. +66 2 398 0793
Turkey: Talatpasa Cad. No. 5, 80640 GÜLTEPE/ISTANBUL,
Tel. +90 212 279 2770, Fax. +90 212 282 6707
Ukraine: PHILIPS UKRAINE, 4 Patrice Lumumba str., Building B, Floor 7,
252042 KIEV, Tel. +380 44 264 2776, Fax. +380 44 268 0461
United Kingdom: Philips Semiconductors Ltd., 276 Bath Road, Hayes,
MIDDLESEX UB3 5BX, Tel. +44 181 730 5000, Fax. +44 181 754 8421
United States: 811 East Arques Avenue, SUNNYVALE, CA 94088-3409,
Tel. +1 800 234 7381
Uruguay: see South America
Vietnam: see Singapore
Yugoslavia: PHILIPS, Trg N. Pasica 5/v, 11000 BEOGRAD,
Tel. +381 11 825 344, Fax.+381 11 635 777
For all other countries apply to: Philips Semiconductors, Marketing & Sales Communications,
Building BE-p, P.O. Box 218, 5600 MD EINDHOVEN, The Netherlands, Fax. +31 40 27 24825
© Philips Electronics N.V. 1996 SCA51
All rights are reserved. Reproduction in whole or in part is prohibited without the prior written consent of the copyright owner.
The information presented in this document does not form part of any quotation or contract, is believed to be accurate and reliable and may be changed
without notice. No liability will be accepted by the publisher for any consequence of its use. Publication thereof does not convey nor imply any license
under patent- or other industrial or intellectual property rights.
Internet: http://www.semiconductors.philips.com
Printed in The Netherlands 617021/1200/01/pp28 Date of release: 1996 Sep 04 Document order number: 9397 750 01139
 Loading...