

Page 1
Features
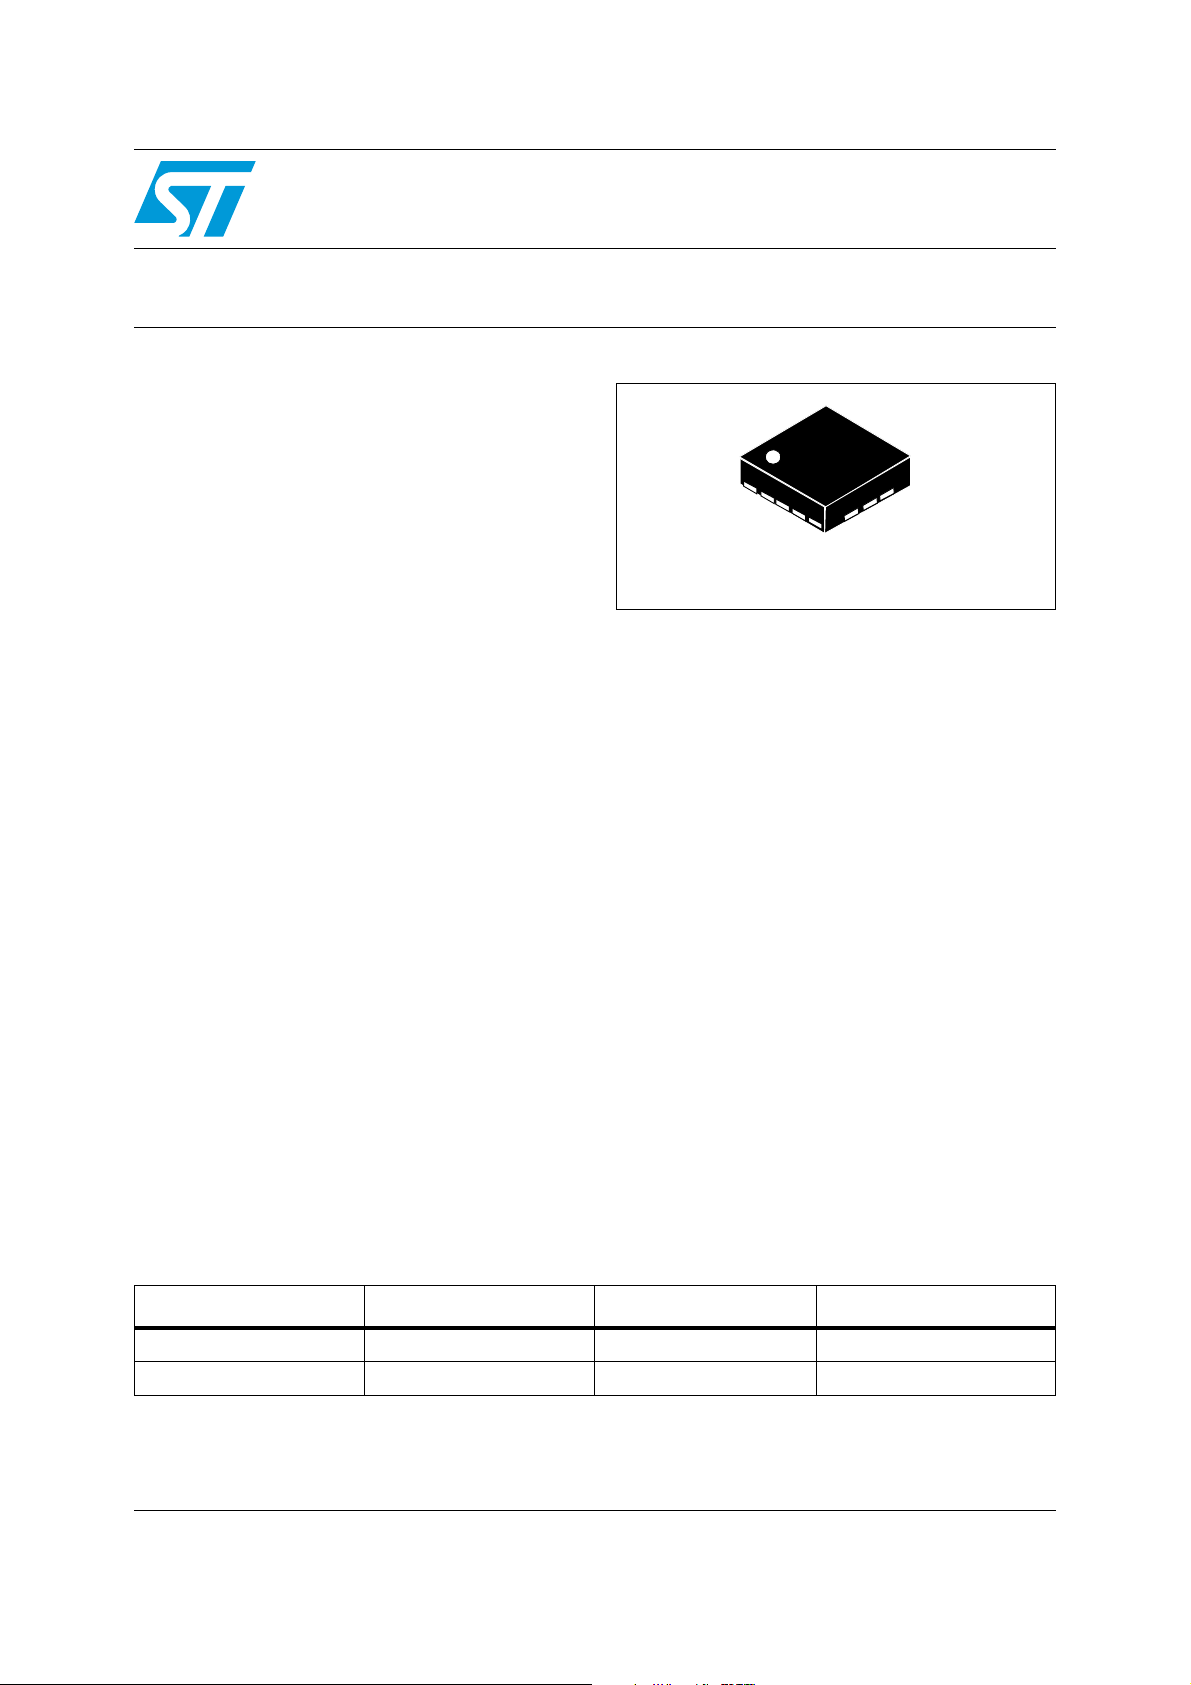
LGA-16
(3x3x1 mm)
■ Wide supply voltage, 2.2 V to 3.6 V
■ Wide extended operating temperature range
(from -40 °C to 85 °C)
■ Low voltage compatible IOs, 1.8 V
■ Low power consumption
■ Embedded power-down
■ Sleep mode
■ Fast turn-on and wake-up
■ Three selectable full scales up to 2000 dps
■ 16 bit rate value data output
■ 8 bit temperature data output
2
■ I
C/SPI digital output interface
■ 2 dedicated lines (1 interrupt, 1 data ready)
■ User enable integrated high-pass filters
■ Embedded temperature sensor
■ Embedded 32 levels of 16 bit data output FIFO
■ High shock survivability
■ ECOPACK
®
RoHS and “Green” compliant
Applications
■ Gaming and virtual reality input devices
■ Motion control with MMI (man-machine
interface)
■ GPS navigation systems
■ Appliances and robotics
L3GD20H
MEMS motion sensor:
three-axis digital output gyroscope
Datasheet — preliminary data
Description
The L3GD20H is a low-power three-axis angular
rate sensor.
It includes a sensing element and an IC interface
able to provide the measured angular rate to the
external world through digital interface (I
The sensing element is manufactured using a
dedicated micromachining process developed by
ST to produce inertial sensors and actuators on
silicon wafers.
The IC interface is manufactured using a CMOS
process that allows a high level of integration to
design a dedicated circuit which is trimmed to
better match the sensing element characteristics.
The L3GD20H has a full scale of
±245/±500/±2000 dps and is capable of
measuring rates with a user selectable
bandwidth.
The L3GD20H is available in a plastic land grid
array (LGA) package and can operate within a
temperature range from -40 °C to +85 °C.
2
C/SPI).
Table 1. Device summary
Order code Temperature range (°C) Package Packing
L3GD20H -40 to +85 LGA-16 (3x3x1) Tray
L3GD20HTR -40 to +85 LGA-16 (3x3x1) Tape and reel
July 2012 Doc ID 023469 Rev 1 1/25
This is preliminar y information on a new product now in development or undergoing evaluation. Details are subject to
change without notice.
www.st.com
25
Page 2
Contents L3GD20H
Contents
1 Block diagram and pin description . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 5
1.1 Pin description . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 5
2 Mechanical and electrical specifications . . . . . . . . . . . . . . . . . . . . . . . . 7
2.1 Mechanical characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 7
2.2 Electrical characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
2.3 Temperature sensor characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
2.4 Communication interface characteristics . . . . . . . . . . . . . . . . . . . . . . . . . 10
2.4.1 SPI - serial peripheral interface . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
2.4.2 I2C - Inter IC control interface . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
2.5 Absolute maximum ratings . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 12
2.6 Terminology . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
2.6.1 Sensitivity . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
2.6.2 Zero-rate level . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
2.7 Soldering information . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 13
3 Digital main blocks . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
3.1 Block diagram . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
3.2 FIFO . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
4 Digital interfaces . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 15
4.1 I2C serial interface . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 15
4.1.1 I2C operation . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 16
4.2 SPI bus interface . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 17
4.2.1 SPI read . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 19
4.2.2 SPI write . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 20
4.2.3 SPI read in 3-wires mode . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 21
5 Package information . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 22
6 Revision history . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 24
2/25 Doc ID 023469 Rev 1
Page 3
L3GD20H List of tables
List of tables
Table 1. Device summary . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 1
Table 2. Pin description . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 6
Table 3. Mechanical characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 7
Table 4. Electrical characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 8
Table 5. Temperature sensor characteristics . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 9
Table 6. SPI slave timing values. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
Table 7. I2C slave timing values. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
Table 8. Absolute maximum ratings . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 12
Table 9. Serial interface pin description . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 15
Table 10. I2C terminology. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 15
Table 11. SAD+Read/Write patterns . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 16
Table 12. Transfer when Master is writing one byte to slave . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 16
Table 13. Transfer when Master is writing multiple bytes to slave . . . . . . . . . . . . . . . . . . . . . . . . . . . 17
Table 14. Transfer when Master is receiving (reading) one byte of data from slave . . . . . . . . . . . . . 17
Table 15. Transfer when Master is receiving (reading) multiple bytes of data from slave . . . . . . . . . 17
Table 16. LGA 3x3x1.0 16L mechanical data. . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 22
Table 17. Document revision history . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 24
Doc ID 023469 Rev 1 3/25
Page 4
List of figures L3GD20H
List of figures
Figure 1. Block diagram . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 5
Figure 2. Pin connection . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 5
Figure 3. SPI slave timing diagram . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 10
Figure 4. I2C slave timing diagram . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 11
Figure 5. Block diagram . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 14
Figure 6. Read and write protocol . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 18
Figure 7. SPI read protocol . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 19
Figure 8. Multiple bytes SPI read protocol (2 bytes example) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 19
Figure 9. SPI write protocol . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 20
Figure 10. Multiple bytes SPI write protocol (2 bytes example) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 20
Figure 11. SPI read protocol in 3-wires mode . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 21
Figure 12. LGA 3x3x1.0 16L mechanical drawing . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . 23
4/25 Doc ID 023469 Rev 1
Page 5
L3GD20H Block diagram and pin description
FIFO
TRIMMING
CIRCUITS
REFERENCE
MIXER
CHARGE
AMP
CLOCK
LOW-PASS
FILTER
+ Ω
x,y,z
I2C
SPI
CS
SCL/SPC
SDA/SDI/SDO
SDO/SA0
Y+
Z+
Y-
Z-
X+
X-
DRIVING MASS
Feedback loop
M
U
X
A
D
D
C
I
G
I
T
A
L
F
I
L
T
E
R
I
N
G
CONTROL LOGIC
&
INTERRUPT GEN.
INT1
DRDY/INT2
DEN
A
D
C
T
E
M
P
E
R
A
T
U
R
E
S
E
N
S
O
R
1
2
&
PHASE GENERATOR
AM12689V1
(TOP VIEW)
DIRECTIONS OF THE
DETECTABLE
ANGULAR RATE
1
X
Vdd_IO
SCL/SPC
SDA/SDI/SDO
SDO/SA0
RES
INT1
DRDY/INT2
CS
DEN
Cap
RES
Vdd
1
8
6
16
+ Ω
Z
+ Ω
X
BOTTOM
VIEW
+ Ω
Y
5
13
9
RES
RES
GND
GND
14
AM12690V1
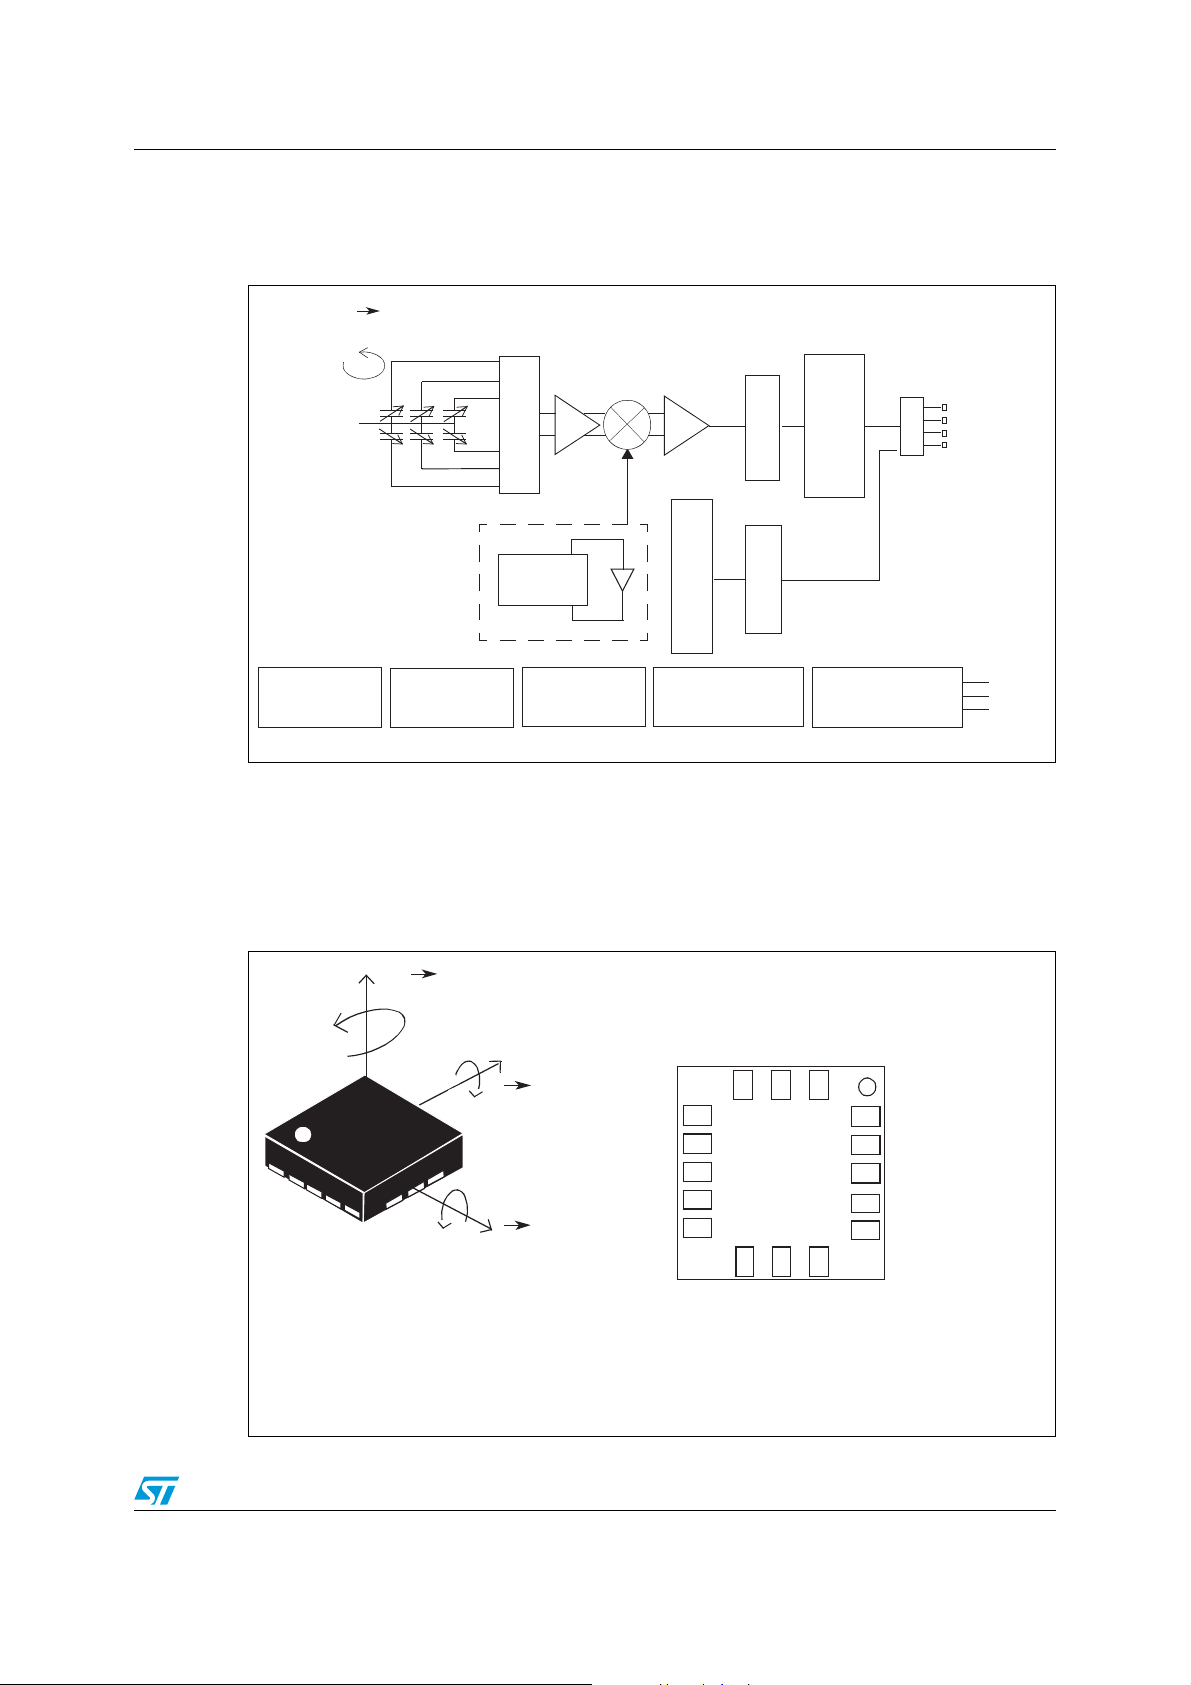
1 Block diagram and pin description
Figure 1. Block diagram
The vibration of the structure is maintained by a drive circuitry in a feedback loop. The
sensing signal is filtered and appears as digital signal at the output.
1.1 Pin description
Figure 2. Pin connection
Doc ID 023469 Rev 1 5/25
Page 6
Block diagram and pin description L3GD20H
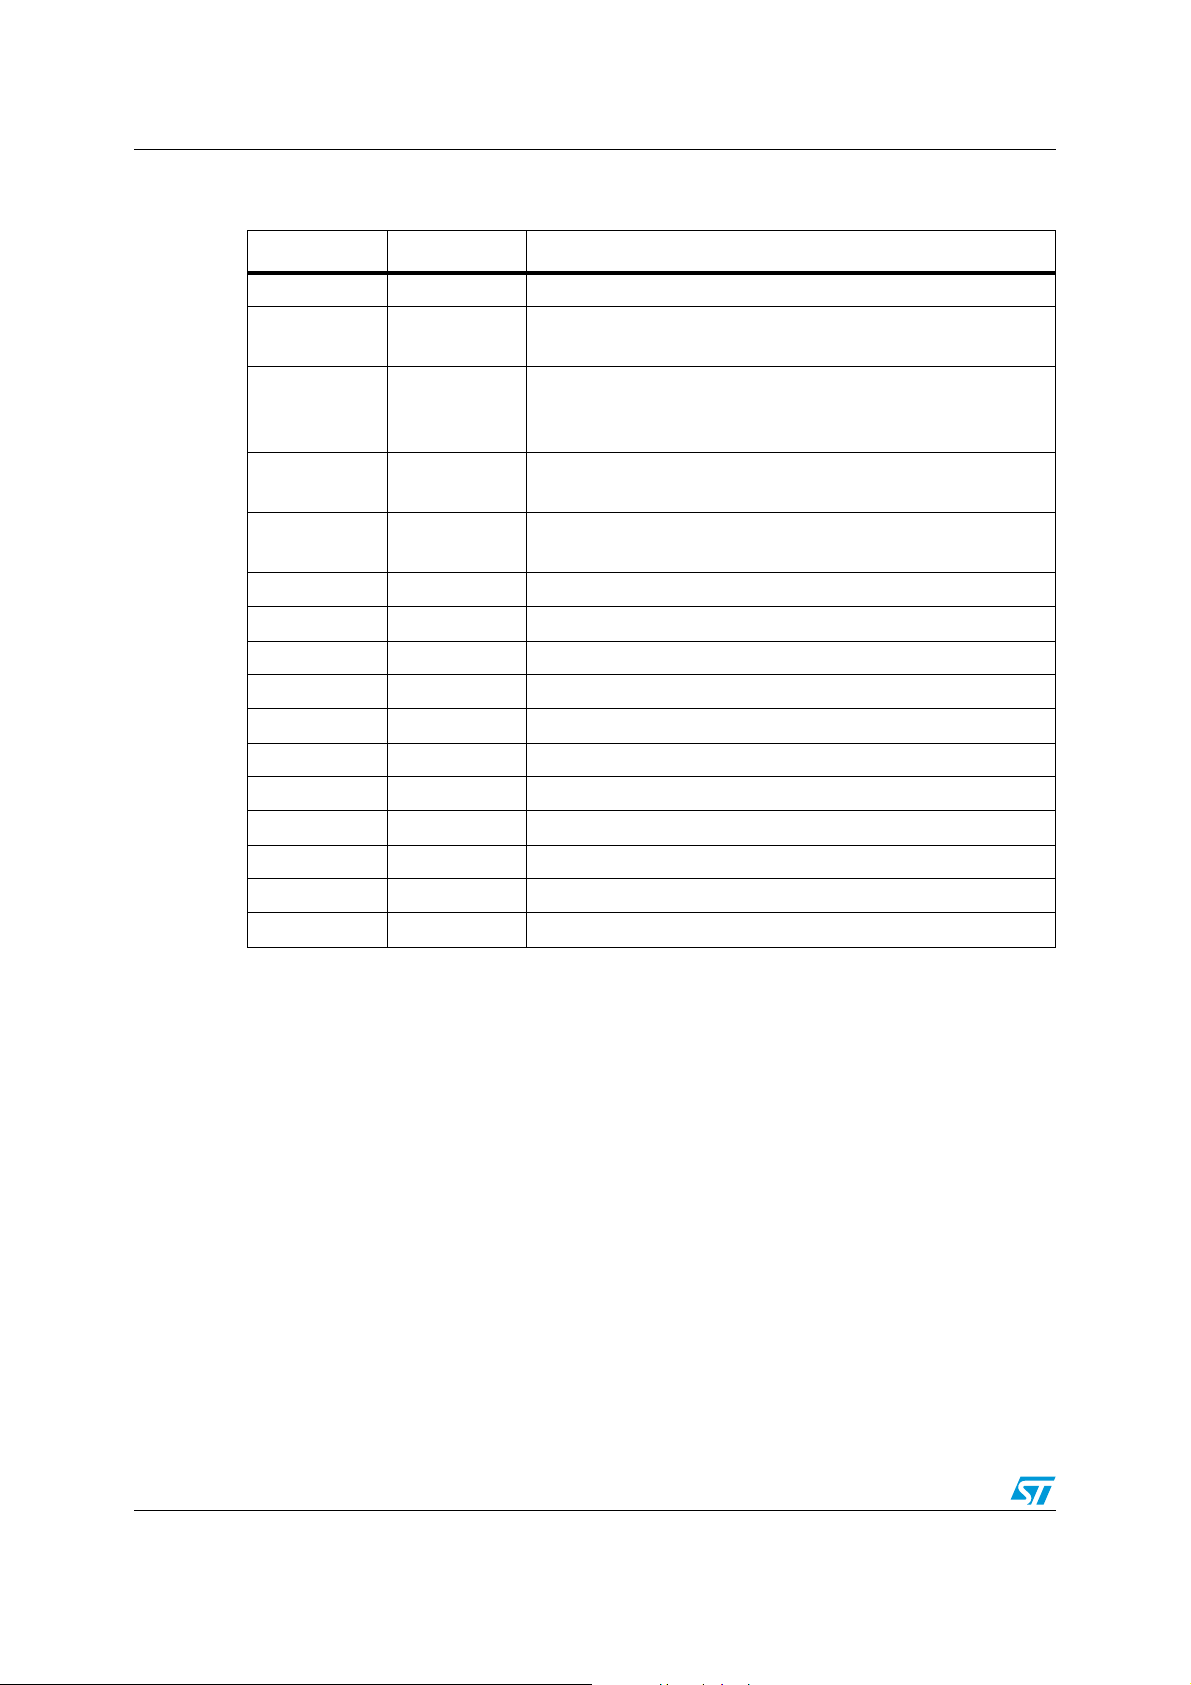
Table 2. Pin description
Pin# Name Function
(1)
1 Vdd_IO
2
SCL
SPC
SDA
3
SDI
SDO
Power supply for I/O pins
2
I
C serial clock (SCL)
SPI serial port clock (SPC)
2
I
C serial data (SDA)
SPI serial data input (SDI)
3-wire interface serial data output (SDO)
4
SDO
SA0
5CS
SPI serial data output (SDO)
2
I
C less significant bit of the device address (SA0)
SPI enable
2
I
C/SPI mode selection (1: I2C mode; 0: SPI enabled)
6 DRDY/INT2 Data ready/fifo interrupt (FIFO Threshold/overrun/empty)
7 INT1 Programmable Interrupt
8 DEN Gyroscope data enable
9 Reserved Connect to GND
10 Reserved Connect to GND
11 Reserved Connect to GND
12 GND 0 V supply
13 GND 0 V supply
14 Cap Connect to GND with ceramic capacitor
(2)
15 Reserved Connect to Vdd
16 Vdd
1. Recommended 100 nF filter capacitor.
2. 10 nF (+/-10%), 25 V. 1 nF minimum value has to be guaranteed under 12 V bias condition.
3. Recommended 100 nF plus 10 μF capacitors.
(3)
Power supply
6/25 Doc ID 023469 Rev 1
Page 7
L3GD20H Mechanical and electrical specifications
dps/ Hz()
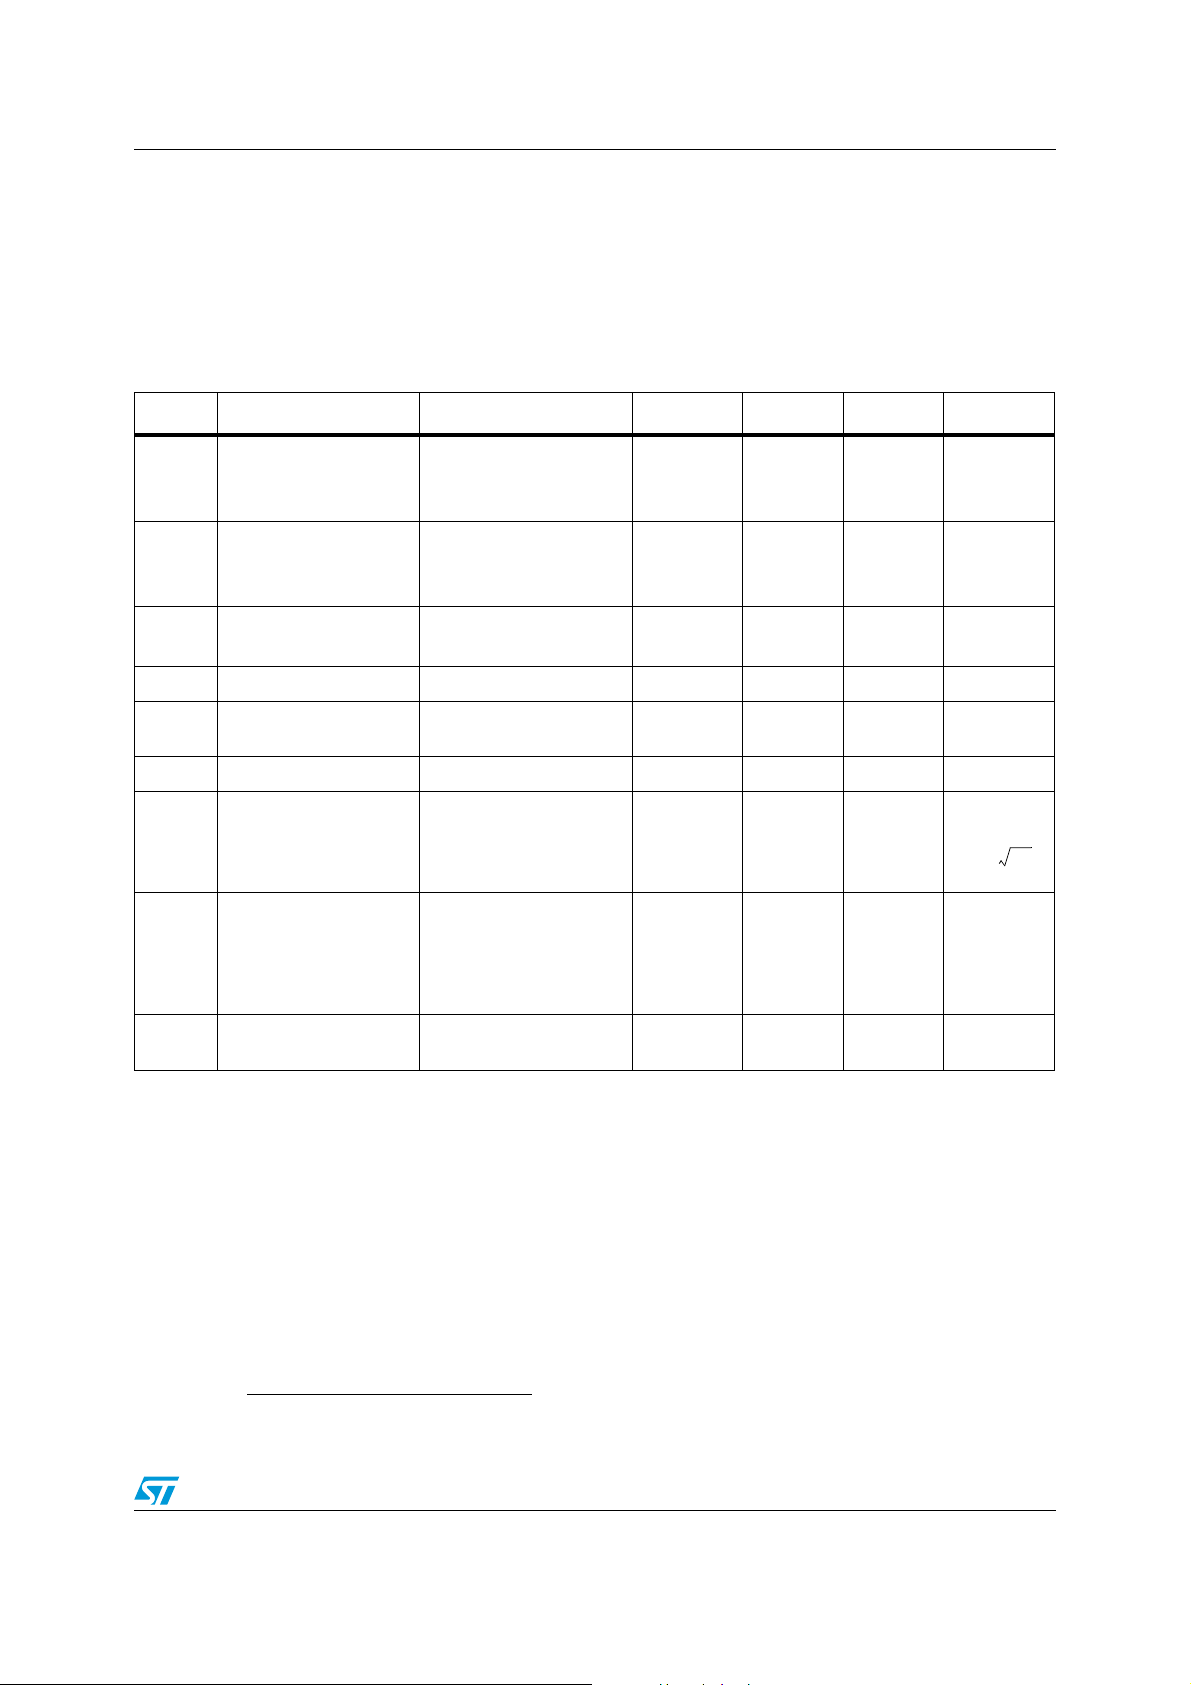
2 Mechanical and electrical specifications
2.1 Mechanical characteristics
@ Vdd = 3.0 V, T = 25 °C unless otherwise noted
Table 3. Mechanical characteristics
Symbol Parameter Test condition Min. Typ.
FS Measurement range User selectable
So Sensitivity
(a)
(1)
±245
±500
±2000
8.75
17.50
70.00
Max. Unit
dps
mdps/digit
SoDr
Sensitivity change vs.
temperature
(2)
From -40 °C to +85 °C
Delta from T = 25 °C
±2 %
DVoff Digital Zero-rate level FS = 2000 dps ±25 dps
OffDr
Zero-rate level change
vs temperature
NL Non linearity
(3)
(3)
Rn Rate noise density
FS = 2000 dps ±0.04 dps/°C
Best fit straight line 0.2 % FS
(3)
BW = 50 Hz 0.011
11.9/23.7/
47.3/94.7/
189.4/
378.8/
Hz
ODR
Digital output data
(3)
rate
757.6
Top
1. Typical specifications are not guaranteed.
2. Guaranteed by design.
3. The period (1/ODR), length of time between two consecutive sampling, must be derived by the reciprocal of the maximum.
and minimum ODR limits: for example for ODR = 189.4 Hz, sampling period range will be within [4591 μs, 6211 μs] (where
ODR minimum and maximum have been approximated at 162 Hz, 219 Hz respectively).
Operating temperature
range
-40 +85 °C
a. The product is factory calibrated at 3.0 V. The operational power supply range is specified in Table 4.
Doc ID 023469 Rev 1 7/25
Page 8
Mechanical and electrical specifications L3GD20H
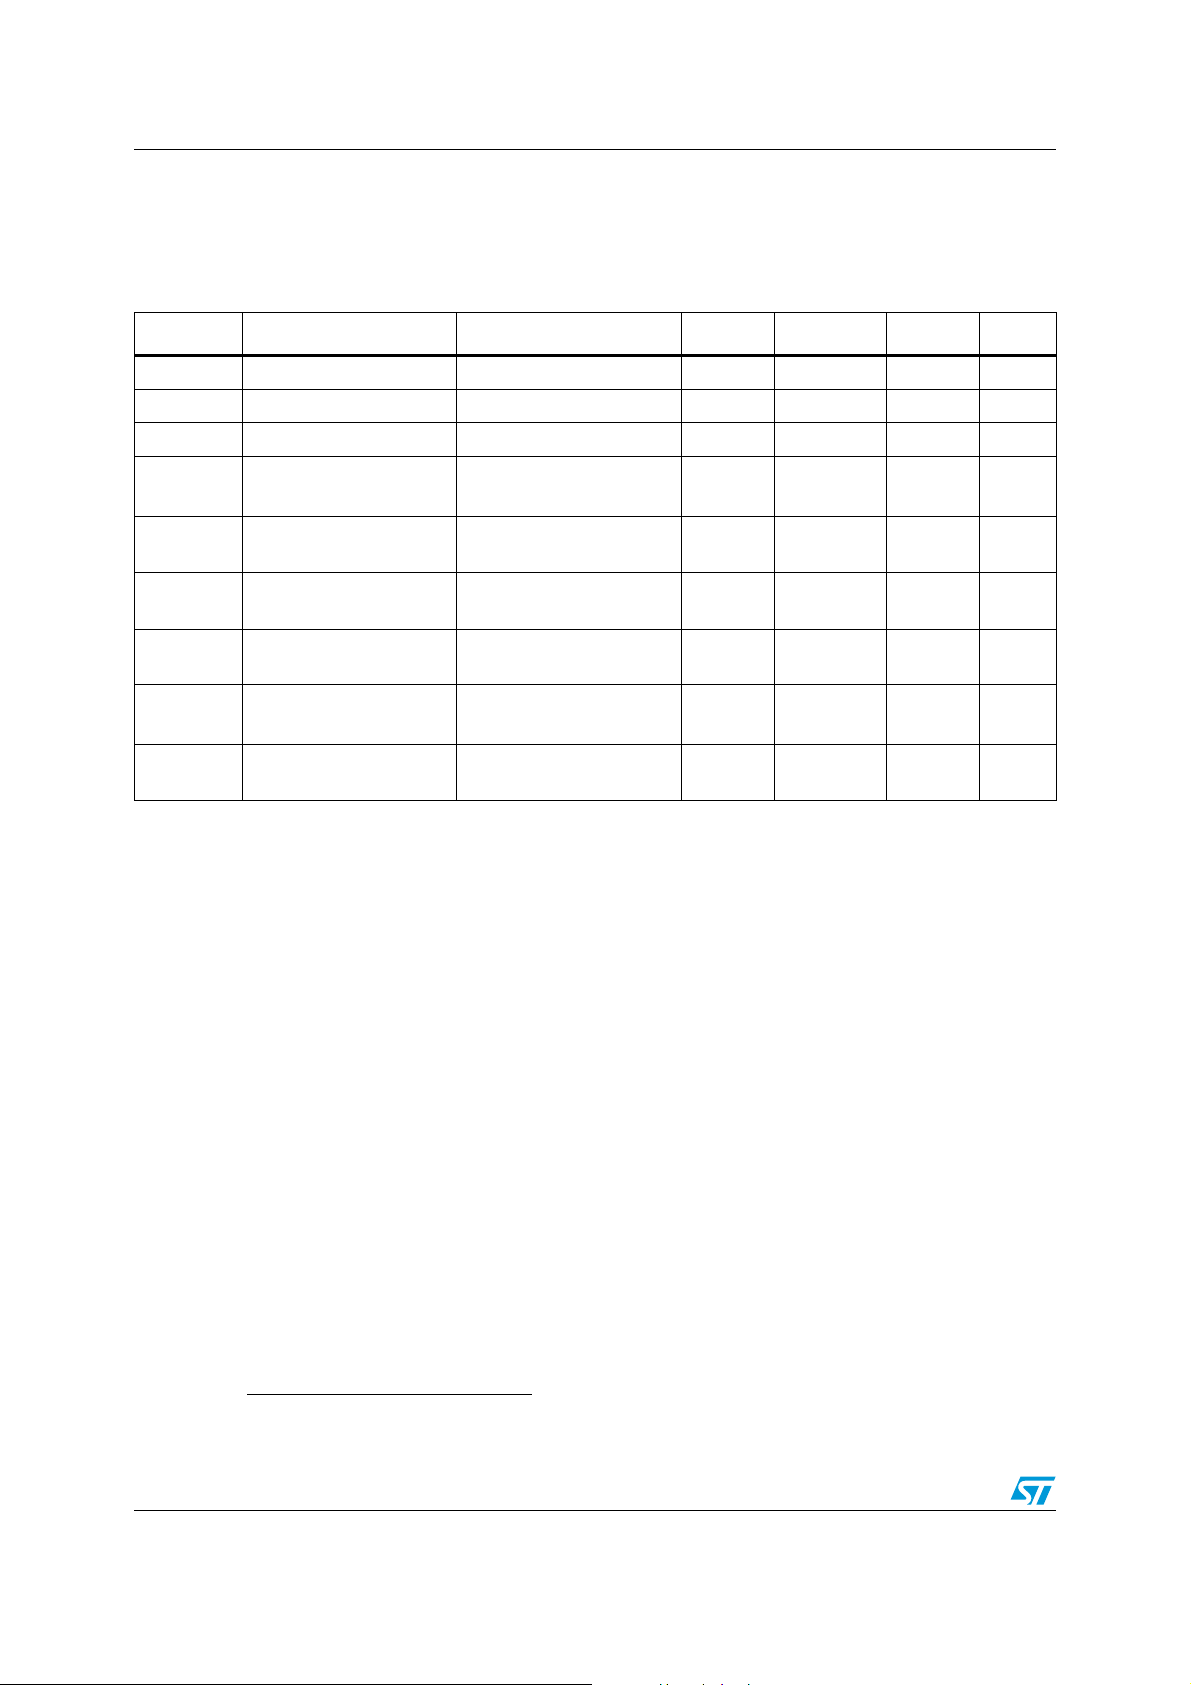
2.2 Electrical characteristics
@ Vdd =3.0 V, T=25 °C unless otherwise noted
Table 4. Electrical characteristics
Symbol Parameter Test condition Min. Typ.
Vdd Supply voltage 2.2 3.0 3.6 V
Vdd_IO I/O pins supply voltage
Idd Supply current 5.0 mA
(2)
(b)
(1)
Max. Unit
1.71 Vdd+0.1 V
IddSL
IddPdn
VIH
VIL
Ton Turn-on time
To p
1. Typical specifications are not guaranteed.
2. It is possible to remove Vdd maintaining Vdd_IO without blocking the communication busses, in this condition the
measurement chain is powered off.
3. Sleep mode introduces a faster turn-on time related to power down mode.
4. Time to obtain stable Sensitivity (within
Supply current
in sleep mode
(3)
Supply current in powerdown mode
Digital high level input
voltage
Digital low level input
voltage
(4)
Operating temperature
range
Selectable by digital
interface
Selectable by digital
interface
2.5 mA
1 μA
0.8*Vdd_I
O
0.2*Vdd_I
O
LPF2 disabled
ODR = 190 Hz
50 ms
-40 +85 °C
±5% of final value) after exiting power-down mode. It is guaranteed by design.
V
V
b. The product is factory calibrated at 3.0 V.
8/25 Doc ID 023469 Rev 1
Page 9

L3GD20H Mechanical and electrical specifications
2.3 Temperature sensor characteristics
@ Vdd =3.0 V, T=25 °C unless otherwise noted
Table 5. Temperature sensor characteristics
Symbol Parameter Test condition Min. Typ.
(c)
(1)
Max. Unit
TSDr
TODR Temperature refresh rate 1 Hz
Top Operating temperature range -40 +85 °C
1. Typical specifications are not guaranteed.
Temperature sensor output
change vs temperature
-1 °C/digit
-
c. The product is factory calibrated at 3.0 V.
Doc ID 023469 Rev 1 9/25
Page 10

Mechanical and electrical specifications L3GD20H
SPC
CS
SDI
SDO
t
su(CS)
t
v(SO)
t
h(SO)
t
h(SI)
t
su(SI)
t
h(CS)
t
dis(SO)
t
c(SPC)
MS B I N
MS B O UT
LSB OUT
LSB IN
2.4 Communication interface characteristics
2.4.1 SPI - serial peripheral interface
Subject to general operating conditions for Vdd and Top.
Table 6. SPI slave timing values
(1)
Val ue
Symbol Parameter
Min Max
tc(SPC) SPI clock cycle 100 ns
fc(SPC) SPI clock frequency 10 MHz
tsu(CS) CS setup time 5
th(CS) CS hold time 20
tsu(SI) SDI input setup time 5
th(SI) SDI input hold time 15
tv(SO) SDO valid output time 50
th(SO) SDO output hold time 5
tdis(SO) SDO output disable time 50
Unit
ns
1. Values are guaranteed at 10 MHz clock frequency for SPI with both 4 and 3 wires, based on characterization results, not
tested in production
Figure 3. SPI slave timing diagram
(d)
d. Measurement points are done at 0.2·Vdd_IO and 0.8·Vdd_IO, for both Input and Output port.
10/25 Doc ID 023469 Rev 1
Page 11

L3GD20H Mechanical and electrical specifications
SDA
SCL
t
f(SDA)
t
su(SP)
t
w(SCLL)
t
su(SDA)
t
r(SDA)
t
su(SR)
t
h(ST)
t
w(SCLH)
t
h(SDA)
t
r(SCL)tf(SCL)
t
w(SP:SR)
START
REPEATED
START
STOP
START
2.4.2 I2C - Inter IC control interface
Subject to general operating conditions for Vdd and Top.
Table 7. I2C slave timing values
Symbol Parameter
I2C Standard mode
(1)
I2C Fast mode
Min. Max. Min. Max.
(1)
Unit
f
(SCL)
t
w(SCLL)
t
w(SCLH)
t
su(SDA)
t
h(SDA)
t
r(SDA) tr(SCL)
t
f(SDA) tf(SCL)
t
h(ST)
t
su(SR)
t
su(SP)
t
w(SP:SR)
1. Data based on standard I2C protocol requirement, not tested in production.
2. Cb = total capacitance of one bus line, in pF.
Figure 4. I
SCL clock frequency 0 100 0 400 kHz
SCL clock low time 4.7 1.3
SCL clock high time 4.0 0.6
SDA setup time 250 100 ns
SDA data hold time 0 3.45 0 0.9 µs
SDA and SCL rise time 1000 20 + 0.1C
SDA and SCL fall time 300 20 + 0.1Cb
START condition hold time 4 0.6
Repeated START condition
setup time
4.7 0.6
STOP condition setup time 4 0.6
Bus free time between STOP
and START condition
2
C slave timing diagram
(e)
4.7 1.3
µs
(2)
b
(2)
300
ns
300
µs
e. Measurement points are done at 0.2·Vdd_IO and 0.8·Vdd_IO, for both ports.
Doc ID 023469 Rev 1 11/25
Page 12
Mechanical and electrical specifications L3GD20H
This is a mechanical shock sensitive device, improper handling can cause permanent
damage to the part
This is an ESD sensitive device, improper handling can cause permanent damage to
the part
2.5 Absolute maximum ratings
Stresses above those listed as “Absolute maximum ratings” may cause permanent damage
to the device. This is a stress rating only and functional operation of the device under these
conditions is not implied. Exposure to maximum rating conditions for extended periods may
affect device reliability.
Table 8. Absolute maximum ratings
Symbol Ratings Maximum value Unit
Vdd Supply voltage -0.3 to 4.8 V
T
ESD Electrostatic discharge protection 2 (HBM) kV
Vin
Note: Supply voltage on any pin should never exceed 4.8 V.
Storage temperature range -40 to +125 °C
STG
Sg Acceleration g for 0.1 ms 10,000 g
Input Voltage on any control pin
(including
0,3 to Vdd_IO +0.3 V
CS,SCL/SPC,SDA/SDI/SDO,SDO/SA0,DEN)
12/25 Doc ID 023469 Rev 1
Page 13

L3GD20H Mechanical and electrical specifications
2.6 Terminology
2.6.1 Sensitivity
An angular rate gyroscope is device that produces a positive-going digital output for
counterclockwise rotation around the sensible axis considered. Sensitivity describes the
gain of the sensor and can be determined by applying a defined angular velocity to it. This
value changes very little over temperature and time.
2.6.2 Zero-rate level
Zero-rate level describes the actual output signal if there is no angular rate present. Zerorate level of precise MEMS sensors is, to some extent, a result of stress to the sensor and
therefore zero-rate level can slightly change after mounting the sensor onto a printed circuit
board or after exposing it to extensive mechanical stress. This value changes very little over
temperature and time.
2.7 Soldering information
The LGA package is compliant with the ECOPACK®, RoHS and “Green” standard.
It is qualified for soldering heat resistance according to JEDEC J-STD-020.
Leave “Pin 1 Indicator” unconnected during soldering.
Land pattern and soldering recommendations are available at www.st.com/mems
.
Doc ID 023469 Rev 1 13/25
Page 14
Digital main blocks L3GD20H
3 Digital main blocks
3.1 Block diagram
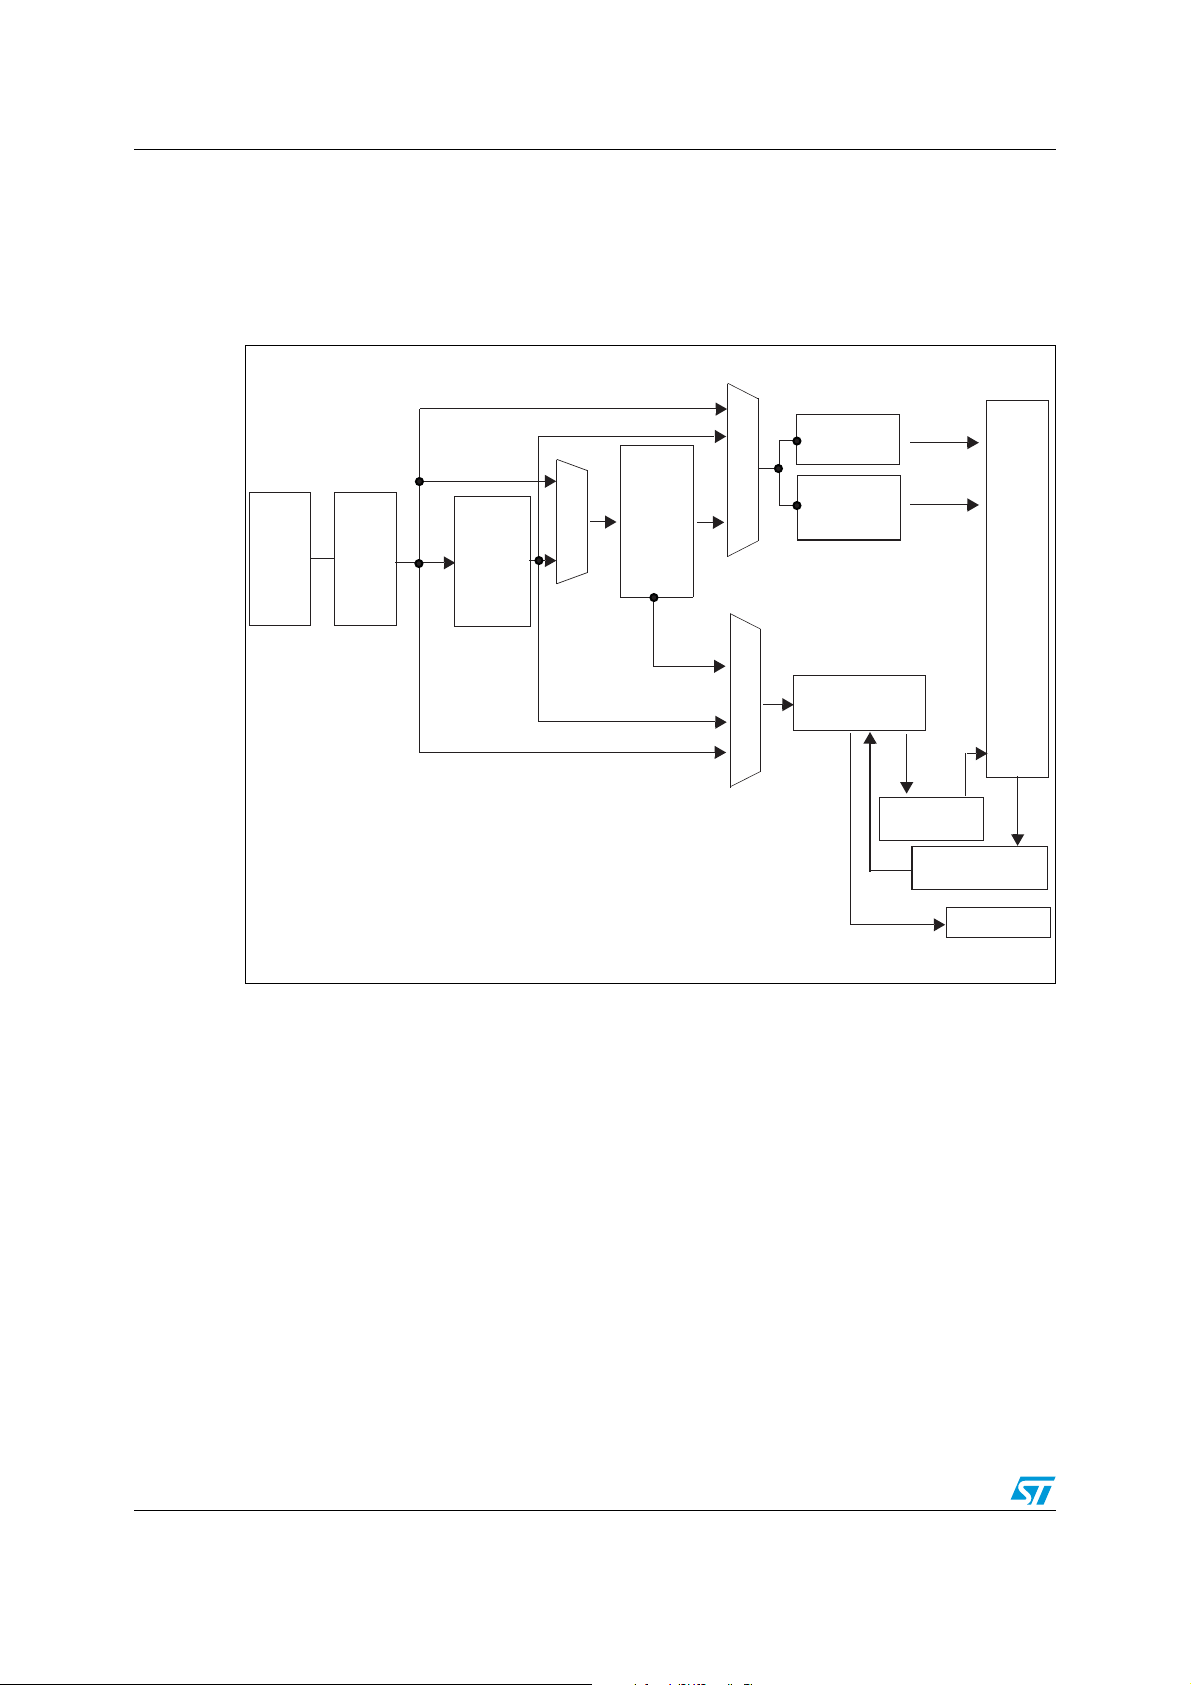
Figure 5. Block diagram
Out_Sel
00
01
DataReg
ADC
3.2 FIFO
LPF1
HPF
0
1
HPen
LPF2
10
11
INT_Sel
10
11
01
00
FIFO
32x16x3
Interrupt
generator
I2C
SPI
SCR REG
CONF REG
INT1
AM07230v1
The L3GD20H embeds a 32-slot, 16 bit data FIFO for each of the three output channels,
yaw, pitch and roll. This allows a consistent power saving for the system, since the host
processor does not need to continuously poll data from the sensor, but it can wake up only
when needed and burst the significant data out from the FIFO. This buffer can work
according to six different modes: Bypass mode, FIFO-mode, Stream mode, Stream-to-FIFO
mode, Bypass-to-Stream, Bypass-to-FIFO.
14/25 Doc ID 023469 Rev 1
Page 15

L3GD20H Digital interfaces
4 Digital interfaces
The registers embedded inside the L3GD20H may be accessed through both the I2C and
SPI serial interfaces. The latter may be SW configured to operate either in 3-wire or 4-wire
interface mode.
The serial interfaces are mapped onto the same pins. To select/exploit the I
line must be tied high (i.e connected to Vdd_IO).
Table 9. Serial interface pin description
Pin name Pin description
2
C interface, CS
CS
SCL/SPC
SDA/SDI/SDO
SDO/SA0
SPI enable
I2C/SPI mode selection (1: I2C mode; 0: SPI enabled)
2
I
C Serial Clock (SCL)
SPI Serial Port Clock (SPC)
2
I
C Serial Data (SDA)
SPI Serial Data Input (SDI)
3-wire Interface Serial Data Output (SDO)
SPI Serial Data Output (SDO)
2
I
C less significant bit of the device address
4.1 I2C serial interface
The L3GD20H I2C is a bus slave. The I2C is employed to write data into registers whose
content can also be read back.
The relevant I
Table 1 0 . I2C terminology
Transmitter The device which sends data to the bus
Receiver The device which receives data from the bus
Master
2
C terminology is given in the table below.
Term Description
The device which initiates a transfer, generates clock signals and terminates a
transfer
Slave The device addressed by the master
There are two signals associated with the I2C bus: the serial clock line (SCL) and the serial
data line (SDA). The latter is a bidirectional line used for sending and receiving the data
to/from the interface. Both the lines must be connected to Vdd_IO through external pull-up
resistor. When the bus is free both the lines are high.
2
The I
C interface is compliant with fast mode (400 kHz) I2C standards as well as with the
normal mode.
Doc ID 023469 Rev 1 15/25
Page 16
Digital interfaces L3GD20H
4.1.1 I2C operation
The transaction on the bus is started through a START (ST) signal. A START condition is
defined as a HIGH to LOW transition on the data line while the SCL line is held HIGH. After
this has been transmitted by the Master, the bus is considered busy. The next byte of data
transmitted after the start condition contains the address of the slave in the first 7 bits and
the eighth bit tells whether the Master is receiving data from the slave or transmitting data to
the slave. When an address is sent, each device in the system compares the first seven bits
after a start condition with its address. If they match, the device considers itself addressed
by the Master.
The Slave ADdress (SAD) associated to the L3GD20H is 110101xb. SDO/SA0 pin can be
used to modify less significant bit of the device address. If SDO/SA0 pin is connected to
voltage supply LSb is ‘1’ (address 1101011b) else if SDO/SA0 pin is connected to ground
LSb value is ‘0’ (address 1101010b). This solution permits to connect and address two
different gyroscopes to the same I
Data transfer with acknowledge is mandatory. The transmitter must release the SDA line
during the acknowledge pulse. The receiver must then pull the data line LOW so that it
remains stable low during the HIGH period of the acknowledge clock pulse. A receiver which
has been addressed is obliged to generate an acknowledge after each byte of data
received.
2
The I
C embedded inside the L3GD20H behaves like a slave device and the following
protocol must be adhered to. After the start condition (ST) a slave address is sent, once a
slave acknowledge (SAK) has been returned, a 8-bit sub-address will be transmitted: the 7
LSb represent the actual register address while the MSB enables address auto increment. If
the MSb of the SUB field is 1, the SUB (register address) will be automatically incremented
to allow multiple data read/write.
2
C bus.
The slave address is completed with a Read/Write bit. If the bit was ‘1’ (Read), a repeated
START (SR) condition will have to be issued after the two sub-address bytes; if the bit is ‘0’
(Write) the Master will transmit to the slave with direction unchanged. Ta bl e 1 1 explains how
the SAD+Read/Write bit pattern is composed, listing all the possible configurations.
Table 11. SAD+Read/Write patterns
Command SAD[6:1] SAD[0] = SDO R/W SAD+R/W
Read 110101 0 1 11010101 (D5h)
Write 110101 0 0 11010100 (D4h)
Read 110101 1 1 11010111 (D7h)
Write 110101 1 0 11010110 (D6h)
Table 12. Transfer when Master is writing one byte to slave
Master ST SAD + W SUB DATA SP
Slave SAK SAK SAK
16/25 Doc ID 023469 Rev 1
Page 17

L3GD20H Digital interfaces
Table 13. Transfer when Master is writing multiple bytes to slave
Master ST SAD + W SUB DATA DATA SP
Slave SAK SAK SAK SAK
Table 14. Transfer when Master is receiving (reading) one byte of data from slave
Master ST SAD + W SUB SR SAD + R NMAK SP
Slave SAK SAK SAK DATA
Table 15. Transfer when Master is receiving (reading) multiple bytes of data from slave
Master ST SAD+W SUB SR SAD+R MAK MAK NMAK SP
Slave SAK SAK SAK DATA DATA DATA
Data are transmitted in byte format (DATA). Each data transfer contains 8 bits. The number
of bytes transferred per transfer is unlimited. Data is transferred with the Most Significant bit
(MSb) first. If a receiver can’t receive another complete byte of data until it has performed
some other function, it can hold the clock line, SCL LOW to force the transmitter into a wait
state. Data transfer only continues when the receiver is ready for another byte and releases
the data line. If a slave receiver doesn’t acknowledge the slave address (i.e. it is not able to
receive because it is performing some real time function) the data line must be left HIGH by
the slave. The Master can then abort the transfer. A LOW to HIGH transition on the SDA line
while the SCL line is HIGH is defined as a STOP condition. Each data transfer must be
terminated by the generation of a STOP (SP) condition.
In order to read multiple bytes, it is necessary to assert the most significant bit of the subaddress field. In other words, SUB(7) must be equal to 1 while SUB(6-0) represents the
address of first register to be read.
In the presented communication format MAK is Master Acknowledge and NMAK is No
Master Acknowledge.
In order to disable the I2C block it is needed to write '1' in bit 3 of register located in address
39h.
4.2 SPI bus interface
The SPI is a bus slave. The SPI allows to write and read the registers of the device.
The Serial Interface interacts with the outside world with 4 wires: CS, SPC, SDI and SDO.
Doc ID 023469 Rev 1 17/25
Page 18
Digital interfaces L3GD20H
CS
SPC
SDI
SDO
RW
AD5 AD4 AD3 AD2 AD1 AD0
DI7 DI6 DI5 DI4 DI3 DI2 DI1 DI0
DO7 DO6 DO5 DO4 DO3 DO2 DO1 DO0
MS
AM10129V1
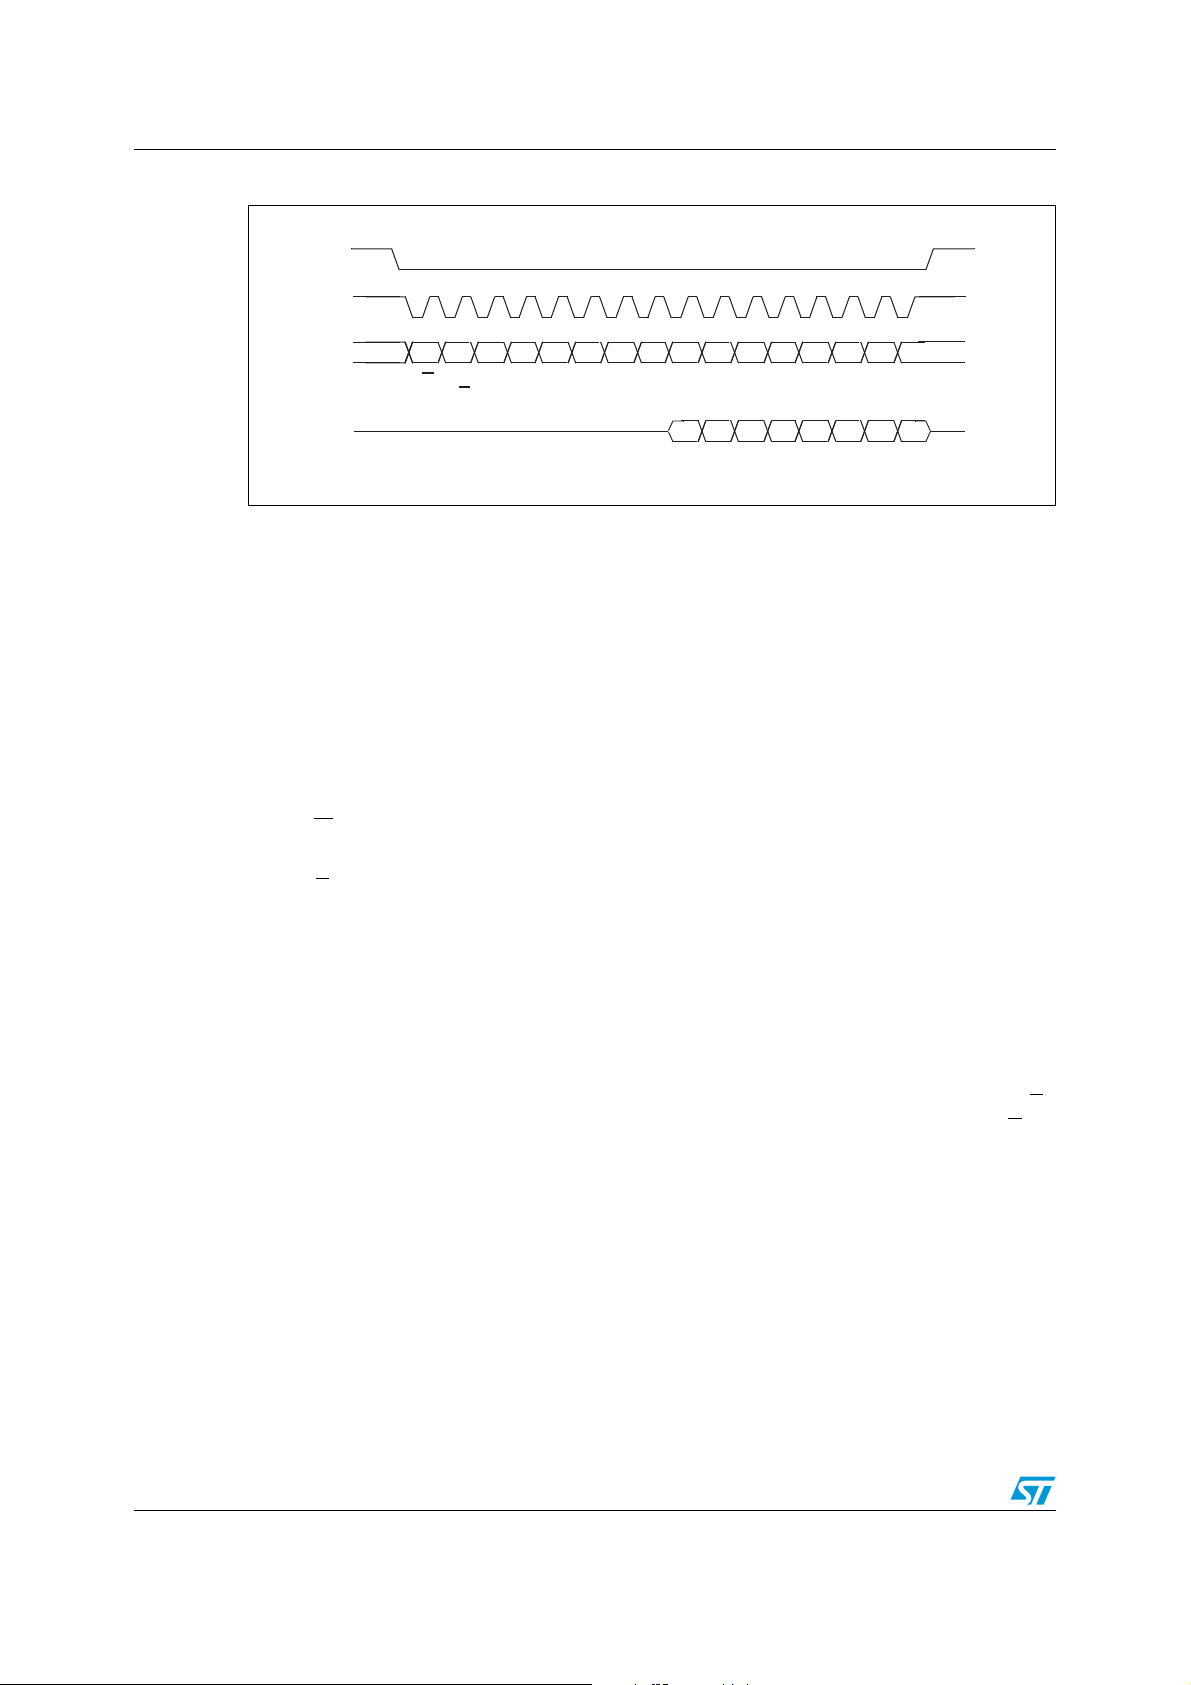
Figure 6. Read and write protocol
CS is the Serial Port Enable and it is controlled by the SPI master. It goes low at the start of
the transmission and goes back high at the end. SPC is the Serial Port Clock and it is
controlled by the SPI master. It is stopped high when CS is high (no transmission). SDI and
SDO are respectively the Serial Port Data Input and Output. Those lines are driven at the
falling edge of SPC and should be captured at the rising edge of SPC.
Both the Read Register and Write Register commands are completed in 16 clock pulses or
in multiple of 8 in case of multiple bytes read/write. Bit duration is the time between two
falling edges of SPC. The first bit (bit 0) starts at the first falling edge of SPC after the falling
edge of CS while the last bit (bit 15, bit 23, ...) starts at the last falling edge of SPC just
before the rising edge of CS.
bit 0: RW
bit. When 0, the data DI(7:0) is written into the device. When 1, the data DO(7:0)
from the device is read. In latter case, the chip will drive SDO at the start of bit 8.
bit 1: MS
bit. When 0, the address will remain unchanged in multiple read/write commands.
When 1, the address will be auto incremented in multiple read/write commands.
bit 2-7: address AD(5:0). This is the address field of the indexed register.
bit 8-15: data DI(7:0) (write mode). This is the data that will be written into the device (MSb
first).
bit 8-15: data DO(7:0) (read mode). This is the data that will be read from the device (MSb
first).
In multiple read/write commands further blocks of 8 clock periods will be added. When MS
bit is 0 the address used to read/write data remains the same for every block. When MS
bit
is 1 the address used to read/write data is incremented at every block.
The function and the behavior of SDI and SDO remain unchanged.
18/25 Doc ID 023469 Rev 1
Page 19

L3GD20H Digital interfaces
CS
SPC
SDI
SDO
RW
DO7 DO6 DO5DO4 DO3 DO2 DO1 DO0
AD5 AD4 AD3 AD2 AD1 AD0
MS
AM10130V1
C S
SPC
SDI
SDO
RW
DO7DO6DO5DO4DO3 DO 2 DO 1 DO 0
AD5 AD4AD3 AD2 AD1 AD0
DO15 DO 14 DO 13 DO 12 DO11 DO 10 D O9 DO8
M S
AM10131V1
4.2.1 SPI read
Figure 7. SPI read protocol
The SPI Read command is performed with 16 clock pulses. Multiple byte read command is
performed adding blocks of 8 clock pulses at the previous one.
bit 0: READ bit. The value is 1.
bit 1: MS
bit. When 0 do not increment address, when 1 increment address in multiple
reading.
bit 2-7: address AD(5:0). This is the address field of the indexed register.
bit 8-15: data DO(7:0) (read mode). This is the data that will be read from the device (MSb
first).
bit 16-... : data DO(...-8). Further data in multiple byte reading.
Figure 8. Multiple bytes SPI read protocol (2 bytes example)
Doc ID 023469 Rev 1 19/25
Page 20

Digital interfaces L3GD20H
CS
SPC
SDI
RW
DI7 DI6 DI5 DI4 DI3 DI2 DI1 DI 0
AD5 AD 4 AD 3 AD2 AD 1 AD0MS
AM10132V1
CS
SPC
SDI
RW
AD5 AD4 AD3 AD2 AD1 AD0
DI7 DI6 DI 5 D I4 DI 3 DI2 DI 1 DI 0 DI15 D I14 DI 13 DI12 DI11 DI 10 DI9 DI 8
MS
AM10133V1
4.2.2 SPI write
Figure 9. SPI write protocol
The SPI Write command is performed with 16 clock pulses. Multiple byte write command is
performed adding blocks of 8 clock pulses at the previous one.
bit 0: WRITE bit. The value is 0.
bit 1: MS
bit. When 0 do not increment address, when 1 increment address in multiple
writing.
bit 2 -7: address AD(5:0). This is the address field of the indexed register.
bit 8-15: data DI(7:0) (write mode). This is the data that will be written inside the device
(MSb first).
bit 16-... : data DI(...-8). Further data in multiple byte writing.
Figure 10. Multiple bytes SPI write protocol (2 bytes example)
20/25 Doc ID 023469 Rev 1
Page 21

L3GD20H Digital interfaces
CS
SPC
SDI/O
RW
DO7 DO6 DO5 DO4 DO3 DO 2 DO1 DO0
AD5 AD 4 AD3 AD2 AD1 AD 0MS
AM10134V1
4.2.3 SPI read in 3-wires mode
Figure 11. SPI read protocol in 3-wires mode
The SPI Read command is performed with 16 clock pulses:
bit 0: READ bit. The value is 1.
bit 1: MS
bit. When 0 do not increment address, when 1 increment address in multiple
reading.
bit 2-7: address AD(5:0). This is the address field of the indexed register.
bit 8-15: data DO(7:0) (read mode). This is the data that will be read from the device (MSb
first).
Multiple read command is also available in 3-wires mode.
Doc ID 023469 Rev 1 21/25
Page 22

Package information L3GD20H
5 Package information
In order to meet environmental requirements, ST offers these devices in different grades of
®
ECOPACK
packages, depending on their level of environmental compliance. ECOPACK
specifications, grade definitions and product status are available at: www.st.com.
ECOPACK is an ST trademark.
Table 16. LGA 3x3x1.0 16L mechanical data
mm
Dim.
Min. Typ. Max.
A1 1
A2 0.785
A3 0.200
D1 2.850 3.000 3.150
E1 2.850 3.000 3.150
L1 1.000 1.060
L2 2.000 2.060
N1 0.500
N2 1.000
M 0.040 0.100
P1 0.875
P2 1.275
T1 0.290 0.350 0.410
T2 0.190 0.250 0.310
d0.150
k0.050
22/25 Doc ID 023469 Rev 1
Page 23

L3GD20H Package information
7983231_M
Figure 12. LGA 3x3x1.0 16L mechanical drawing
Doc ID 023469 Rev 1 23/25
Page 24

Revision history L3GD20H
6 Revision history
Table 17. Document revision history
Date Revision Changes
20-Jul-2012 1 Initial release.
24/25 Doc ID 023469 Rev 1
Page 25

L3GD20H
Please Read Carefully:
Information in this document is provided solely in connection with ST products. STMicroelectronics NV and its subsidiaries (“ST”) reserve the
right to make changes, corrections, modifications or improvements, to this document, and the products and services described herein at any
time, without notice.
All ST products are sold pursuant to ST’s terms and conditions of sale.
Purchasers are solely responsible for the choice, selection and use of the ST products and services described herein, and ST assumes no
liability whatsoever relating to the choice, selection or use of the ST products and services described herein.
No license, express or implied, by estoppel or otherwise, to any intellectual property rights is granted under this document. If any part of this
document refers to any third party products or services it shall not be deemed a license grant by ST for the use of such third party products
or services, or any intellectual property contained therein or considered as a warranty covering the use in any manner whatsoever of such
third party products or services or any intellectual property contained therein.
UNLESS OTHERWISE SET FORTH IN ST’S TERMS AND CONDITIONS OF SALE ST DISCLAIMS ANY EXPRESS OR IMPLIED
WARRANTY WITH RESPECT TO THE USE AND/OR SALE OF ST PRODUCTS INCLUDING WITHOUT LIMITATION IMPLIED
WARRANTIES OF MERCHANTABILITY, FITNESS FOR A PARTICULAR PURPOSE (AND THEIR EQUIVALENTS UNDER THE LAWS
OF ANY JURISDICTION), OR INFRINGEMENT OF ANY PATENT, COPYRIGHT OR OTHER INTELLECTUAL PROPERTY RIGHT.
UNLESS EXPRESSLY APPROVED IN WRITING BY TWO AUTHORIZED ST REPRESENTATIVES, ST PRODUCTS ARE NOT
RECOMMENDED, AUTHORIZED OR WARRANTED FOR USE IN MILITARY, AIR CRAFT, SPACE, LIFE SAVING, OR LIFE SUSTAINING
APPLICATIONS, NOR IN PRODUCTS OR SYSTEMS WHERE FAILURE OR MALFUNCTION MAY RESULT IN PERSONAL INJURY,
DEATH, OR SEVERE PROPERTY OR ENVIRONMENTAL DAMAGE. ST PRODUCTS WHICH ARE NOT SPECIFIED AS "AUTOMOTIVE
GRADE" MAY ONLY BE USED IN AUTOMOTIVE APPLICATIONS AT USER’S OWN RISK.
Resale of ST products with provisions different from the statements and/or technical features set forth in this document shall immediately void
any warranty granted by ST for the ST product or service described herein and shall not create or extend in any manner whatsoever, any
liability of ST.
ST and the ST logo are trademarks or registered trademarks of ST in various countries.
Information in this document supersedes and replaces all information previously supplied.
The ST logo is a registered trademark of STMicroelectronics. All other names are the property of their respective owners.
© 2012 STMicroelectronics - All rights reserved
STMicroelectronics group of companies
Australia - Belgium - Brazil - Canada - China - Czech Republic - Finland - France - Germany - Hong Kong - India - Israel - Italy - Japan -
Malaysia - Malta - Morocco - Philippines - Singapore - Spain - Sweden - Switzerland - United Kingdom - United States of America
www.st.com
Doc ID 023469 Rev 1 25/25
 Loading...