

Page 1

INTEGRATED CIRCUITS
83C576/87C576
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D,
4 comparators, failure detect circuitry, watchdog timer
Product specification
Supersedes data of 1998 Jan 06
IC20 Data Handbook
1998 Jun 04
Page 2
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
FEA TURES
•80C51 based architecture
– 8k × 8 ROM (83C576)
– 8k × 8 EPROM (87C576)
– 256 × 8 RAM
– 10-bit, 6 channel A/D
– Three 16-bit counter/timers
– 2 PWM outputs
– Programmable Counter Array
– Universal Peripheral Interface
– Enhanced UART
– Oscillator fail detect
– Low active reset
– 4 analog comparators
– Watchdog timer
– Low V
– Power-on detect
CC
detect
•Memory addressing capability
– 64k ROM and 64k RAM
•Power control modes:
– Idle mode
– Power-down mode
•CMOS and TTL compatible
•6 to 16MHz
•Extended temperature ranges
•OTP available
•That can be programmed in circuit
•Software Reset
•15 source, 2 level interrupt structure
•Lower EMI noise
•Programmable I/O pins
•Serial on-board programming
•Schmitt trigger inputs on Port 1
DESCRIPTION
The Philips 83C576/87C576 is a high-performance microcontroller
fabricated with Philips high-density CMOS technology. The Philips
CMOS technology combines the high speed and density
characteristics of HMOS with the low power attributes of CMOS.
Philips epitaxial substrate minimizes latch-up sensitivity.
The 8XC576 contains an 8k × 8 ROM (83C576) EPROM (87C576),
a 256 × 8 RAM, 32 I/O lines, three 16-bit counter/timers, a
Programmable Counter Array (PCA), a 10-bit, 6 channel A/D,
2 PWM outputs, an 8-bit UPI interface, a fifteen-source, two-priority
level nested interrupt structure, an enhanced UART, four analog
comparators, power-fail detect and oscillator fail detect circuits, and
on-chip oscillator and clock circuits.
In addition, the 8XC576 has a low active reset, and a software reset.
There is also a fully configurable watchdog timer, and internal power
on clear circuit. The part includes idle mode and power-down mode
states for reduced power consumption.
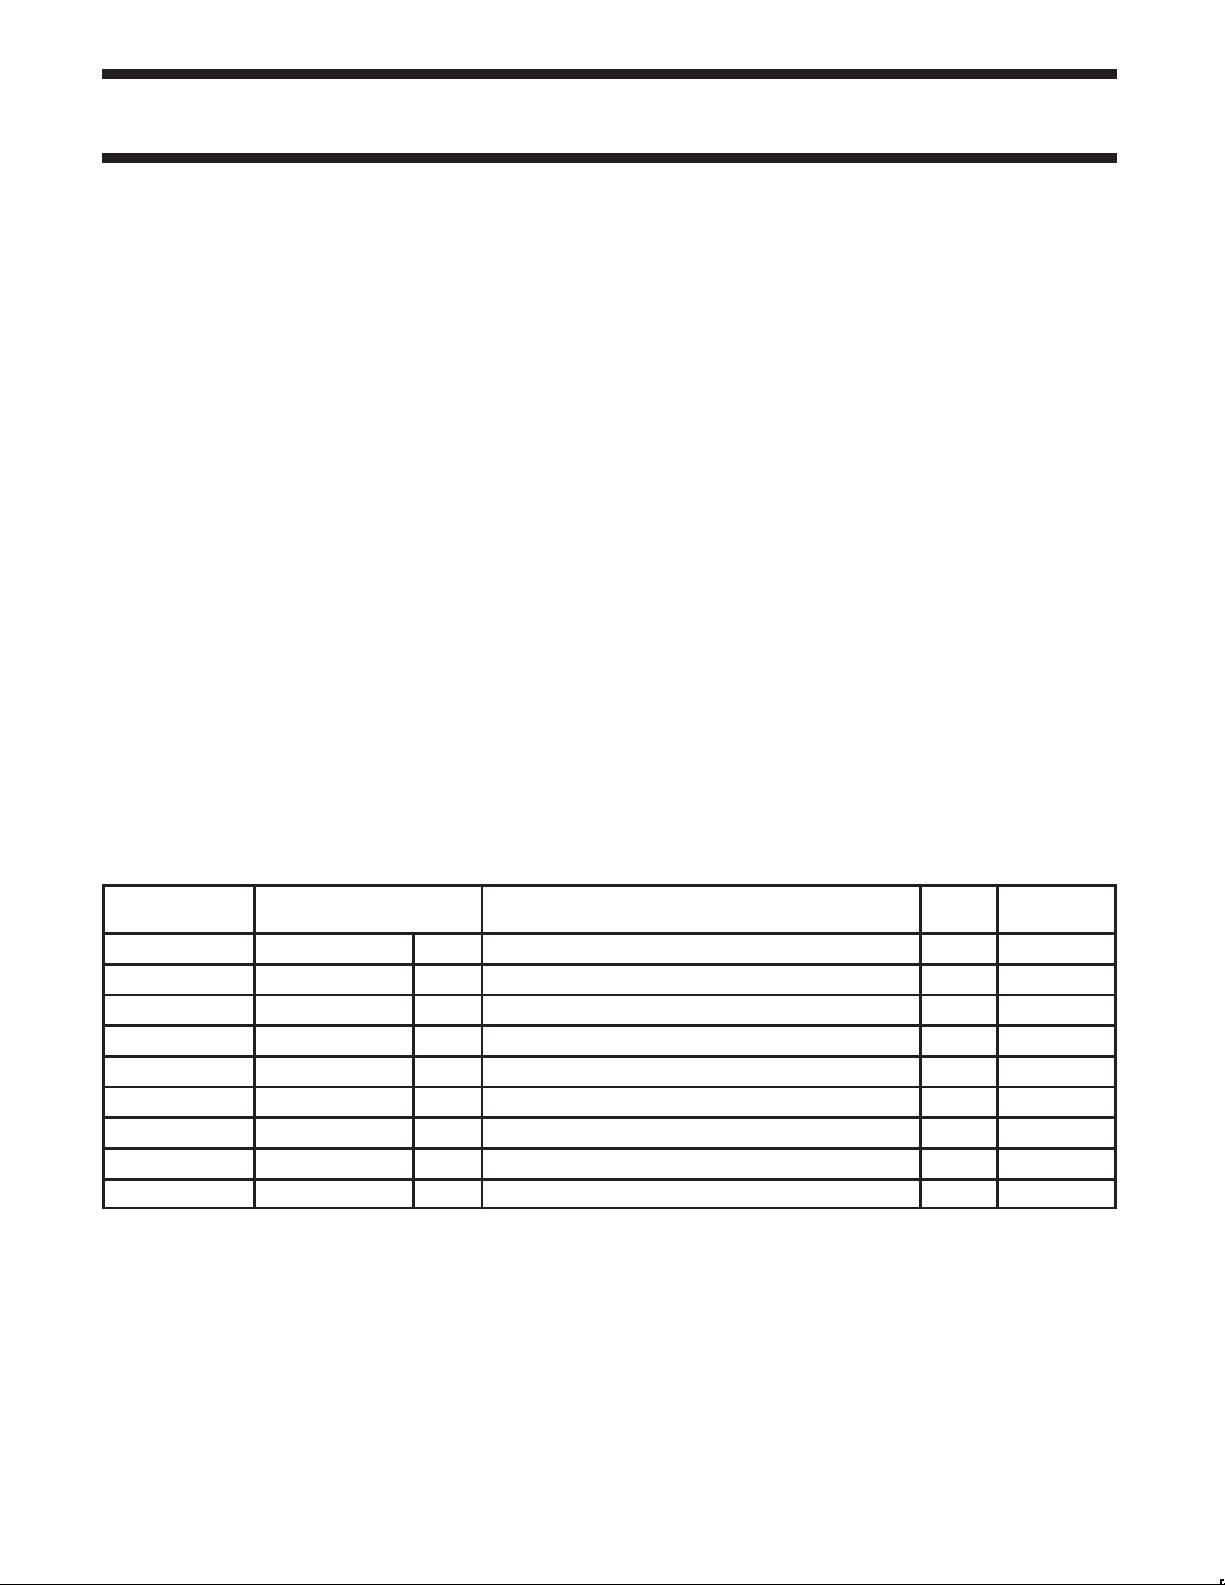
ORDERING INFORMATION
ROM EPROM
P83C576EBPN P87C576EBPN OTP 0 to +70, 40-Pin Plastic Dual In-line Package 16 SOT129-1
P83C576EBAA P87C576EBAA OTP 0 to +70, 44-Pin Plastic Leaded Chip Carrier 16 SOT187-2
P83C576EBBB P87C576EBBB OTP 0 to +70, 44-Pin Plastic Quad Flat Pack 16 SOT307-2
P83C576EFPN P87C576EBPN OTP –40 to +85, 40-Pin Plastic Dual In-line Package 16 SOT129-1
P83C576EFAA P87C576EFAA OTP –40 to +85, 44-Pin Plastic Leaded Chip Carrier 16 SOT187-2
P83C576EFBB P87C576EFBB OTP –40 to +85, 44-Pin Plastic Quad Flat Pack 16 SOT307-2
P83C576EHPN P87C576EHPN OTP –40 to +125, 40-Pin Plastic Dual In-line Package 16 SOT129-1
P83C576EHAA P87C576EHAA OTP –40 to +125, 44-Pin Plastic Leaded Chip Carrier 16 SOT187-2
P83C576EHBB P87C576EHBB OTP –40 to +125, 44-Pin Plastic Quad Flat Pack 16 SOT307-2
NOTE:
1. OTP - One Time Programmable EPROM.
1
TEMPERATURE RANGE °C AND PACKAGE
FREQ
(MHz)
DRAWING
NUMBER
1998 Jun 04 853-2067 19495
2
Page 3
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
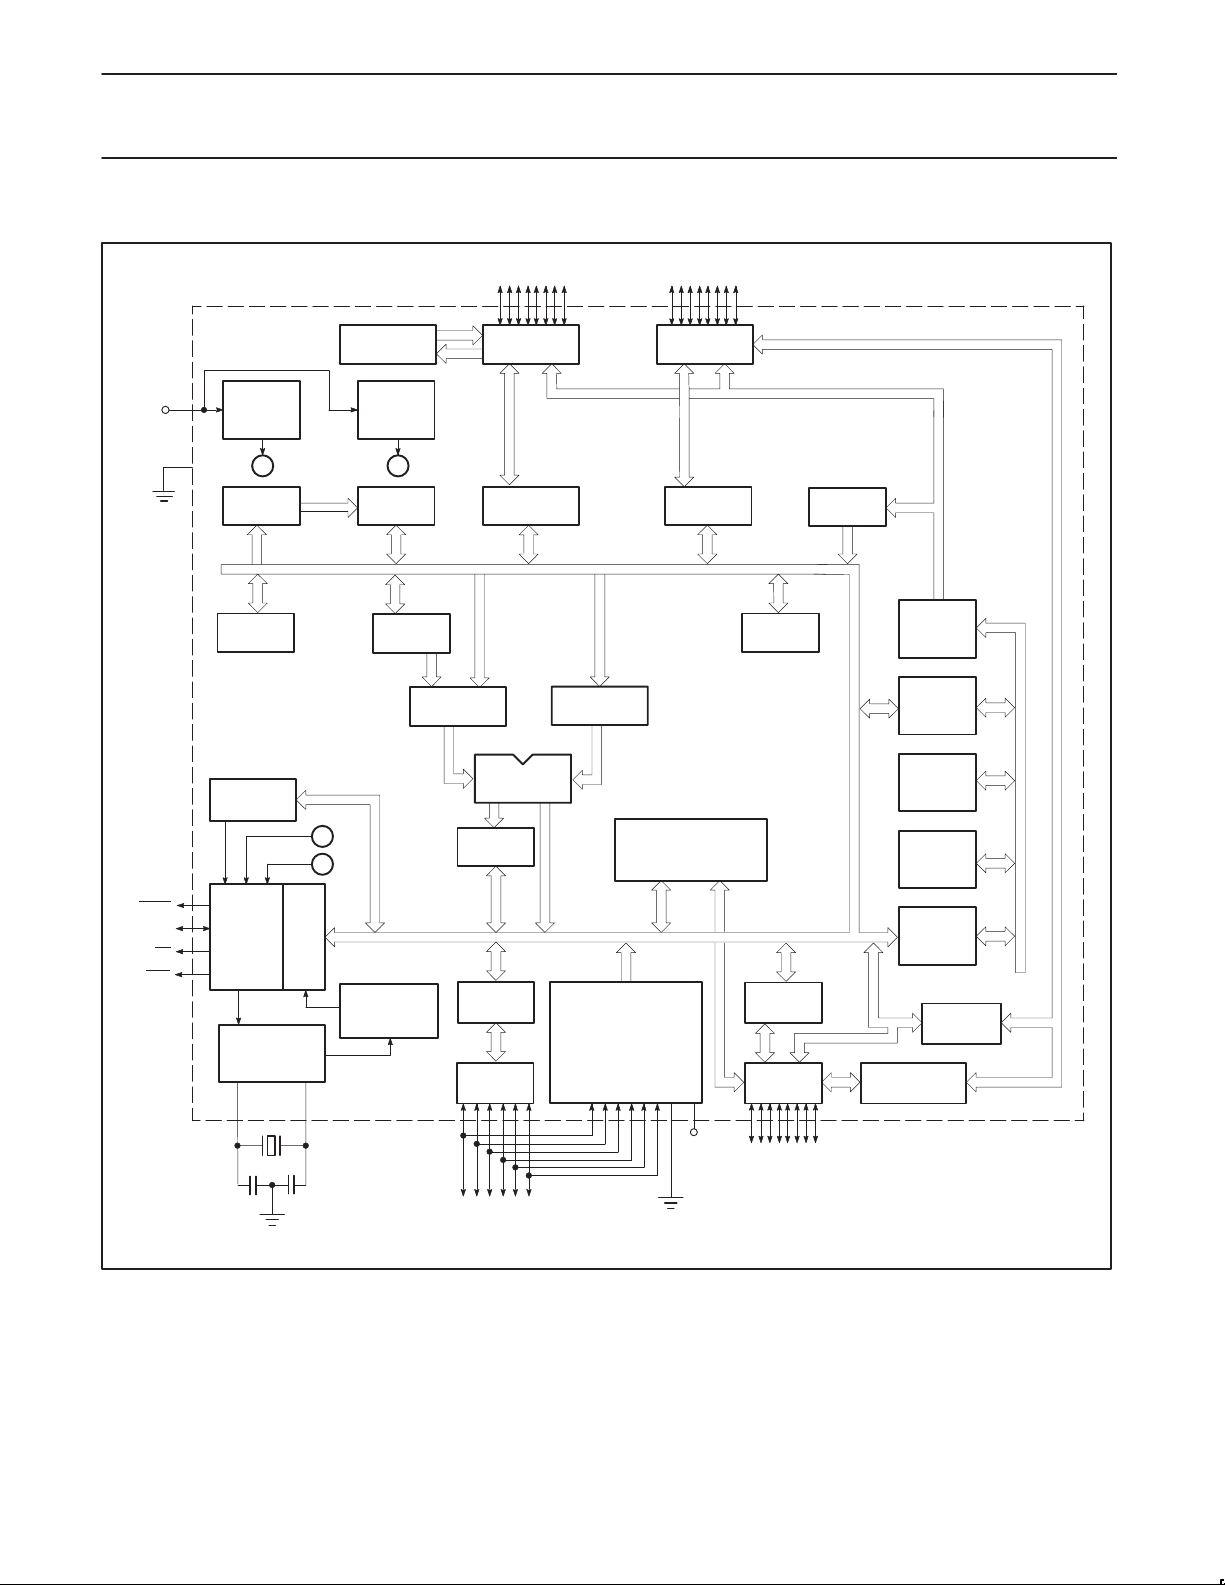
BLOCK DIAGRAM
P0.0-P0.7 P2.0-P2.7
83C576/87C576
V
CC
PSEN
V
SS
REGISTER
WATCHDOG
ALE
EA
RST
TIMING
CONTROL
XTAL1 XTAL2
UPI
CONTROL
LOW
VOLTAGE
DETECT
AB
RAM ADDR
REGISTER
B
TIMER
AND
INSTRUCTION
PD
OSCILLATOR
B
A
REGISTER
CLK AND OSC
POWER
ON
DETECT
RAM
FAILURE
DETECT
ACC
TMP2
DRIVERS
PSW
PORT 1
LATCH
PORT 1
DRIVERS
PORT 0
PORT 0
LATCH
ALU
TMP1
TIMERS
10-BIT
ANALOG TO DIGITAL
CONVERTER
PORT 2
DRIVERS
PORT 2
LATCH
SFRs
PCA
STACK
POINTER
PORT 3
LATCH
PORT 3
DRIVERS
ROM/
EPROM
PROGRAM
ADDRESS
REGISTER
BUFFER
PC
INCRE-
MENTER
PROGRAM
COUNTER
DPTR
COMPARATOR
BLOCK
PWM
1998 Jun 04
P1.0-P1.5
+AV
CC
P3.0-P3.7
–AV
SS
SU00255B
3
Page 4
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
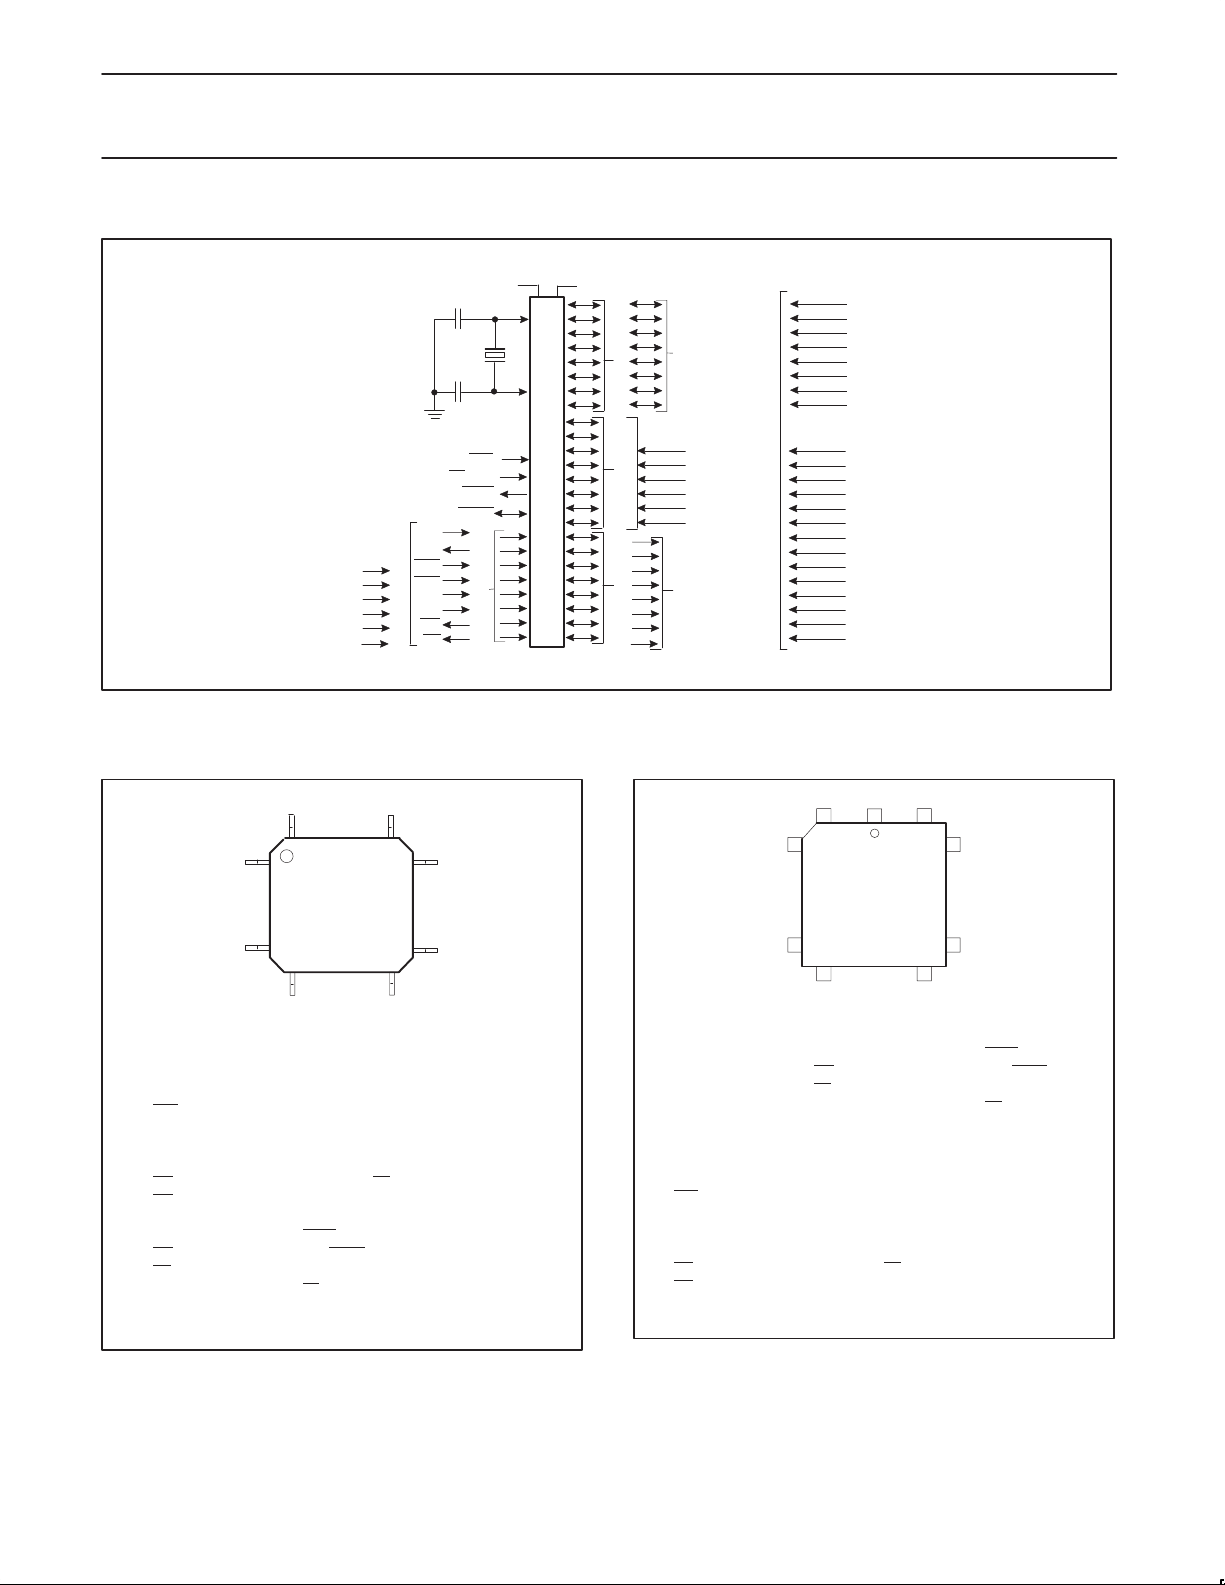
LOGIC SYMBOL
V
V
SS
CC
XTAL1
XTAL2
ADDRESS AND
DATA BUS
PORT 0
83C576/87C576
DB0
DB1
DB2
DB3
DB4
DB5
DB6
DB7
CMP3+
CMP2+
CMP1+
CMPR–
CMP0+
CMP0–
PIN CONFIGURA TIONS
44-pin Plastic Quad Flat Pack
44 34
1
PQFP
11
12 22
Pin Function
1 ADIN3/P1.3
2 ADIN4/P1.4
3 ADIN5/P1.5
4 RST
5 RxD/P3.0
6 NC*
7 TXD/P3.1
0/P3.2/CMP3+
8 INT
1/P3.3/CMP2+
9 INT
10 T0/P3.4/CMP1+
11 T1/P3.5/CMPR–
/P3.6/CMP0+
12 WR
13 RD
/P3.7CMP0–
14 XTAL2
15 XTAL1
* NO INTERNAL CONNECTION
Pin Function
16 V
SS
17 NC*
18 P2.0/A8/CEX0/CMP0
19 P2.1/A9/CEX1/CMP1
20 P2.2/A10/CEX2/CMP2
21 P2.3/A11/CEX3/CMP3
22 P2.4/A12/T2EX/A0
23 P2.5/A13/T2/CS
24 P2.6/A14/CEX4/PWM0
25 P2.7/A15/PWM1/ECI
26 PSEN
27 ALE/PROG
28 NC*
/V
29 EA
PP
30 P0.7/AD7/DB7
EA/V
PSEN
ALE/PROG
RxD
TxD
INT0
INT1
T0
T1
WR
RD
SECONDARY FUNCTIONS
33
23
Pin Function
31 P0.6/AD6/DB6
32 P0.5/AD5/DB5
33 P0.4/AD4/DB4
34 P0.3/AD3/DB3
35 P0.2/AD2/DB2
36 P0.1/AD1/DB1
37 P0.0/AD0/DB0
38 V
39 NC*
40 +V
41 –V
42 ADIN0/P1.0
43 ADIN1/P1.1
44 ADIN2/P1.2
RST
PP
PORT 3
CC
REF
REF
/AV
CC
/AV
SS
SU00253B
ADIN0
ADIN1
PORT 1PORT 2
SECONDARY FUNCTIONS
ADDRESS BUS
ADIN2
ADIN3
ADIN4
ADIN5
PWM1/ECI
CEX4/PWM0
T2/CS#
T2EX/A0
CEX3/CMP3
CEX2/CMP2
CEX1/CMP1
CEX0/CMP0
SU00254A
Plastic Leaded Chip Carrier
6140
7
LCC
17
18 28
Pin Function
1 NC*
2+V
/AV
REF
3–V
4 ADIN0/P1.0
5 ADIN1/P1.1
6 ADIN2/P1.2
7 ADIN3/P1.3
8 ADIN4/P1.4
9 ADIN5/P1.5
10 RST
11 RxD/P3.0
12 NC*
13 TxD/P3.1
14 INT
15 INT
* NO INTERNAL CONNECTION
CC
/AV
REF
SS
0/P3.2/CMP3+
1/P3.3/CMP2+
Pin Function
16 T0/P3.4/CMP1+
17 T1/P3.5/CMPR–
/P3.6/CMP0+
18 WR
19 RD
/P3.7/CMP0–
20 XTAL2
21 XTAL1
22 V
SS
23 NC*
24 P2.0/A8/CEX0/CMP0
25 P2.1/A9/CEX1/CMP1
26 P2.2/A10/CEX2/CMP2
27 P2.3/A11/CEX3/CMP3
28 P2.4/A12/T2EX/A0
29 P2.5/A13/T2/CS
30 P2.6/A14/CEX4/PWM0
39
29
Pin Function
31 P2.7/A15/PWM1/ECI
32 PSEN
33 ALE/PROG
34 NC*
/V
35 EA
PP
36 P0.7/AD7/DB7
37 P0.6/AD6/DB6
38 P0.5/AD5/DB5
39 P0.4/AD4/DB4
40 P0.3/AD3/DB3
41 P0.2/AD2/DB2
42 P0.1/AD1/DB1
43 P0.0/AD0/DB0
44 V
CC
SU00252A
1998 Jun 04
4
Page 5
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
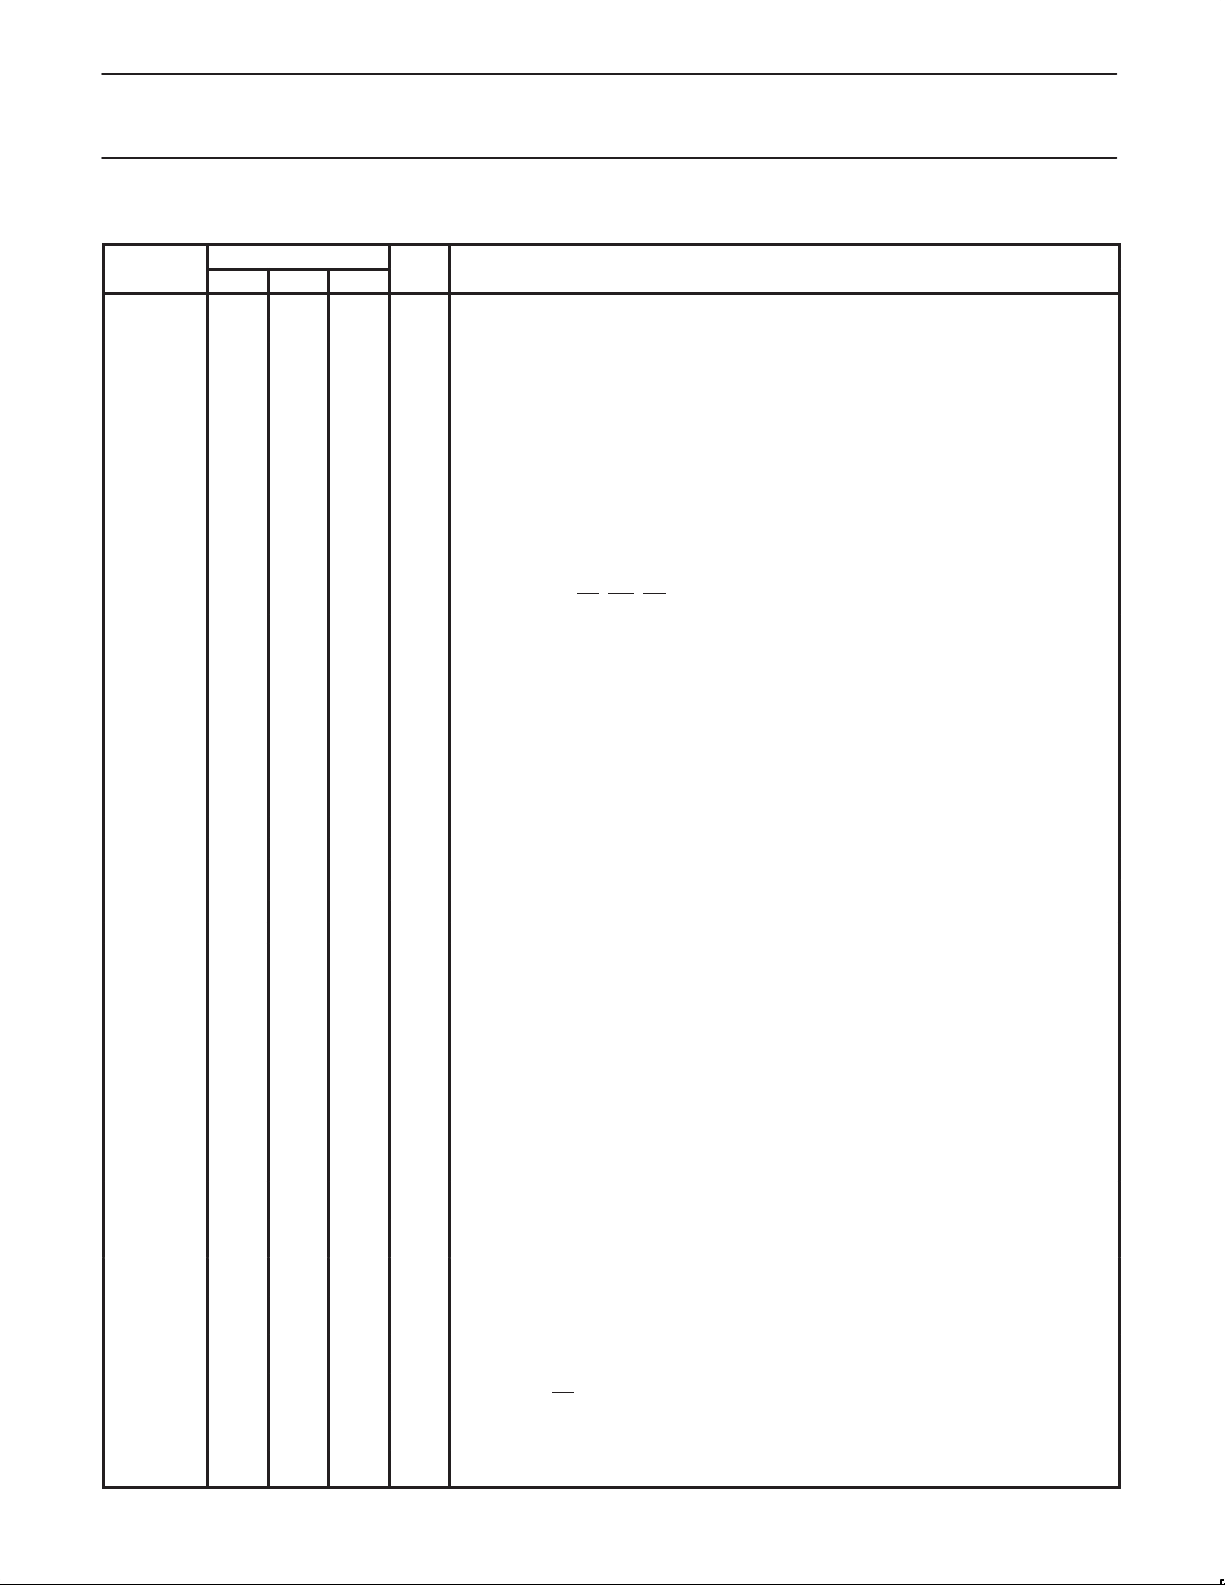
PIN DESCRIPTIONS
PIN NUMBER
MNEMONIC
V
SS
V
CC
P0.0-0.7 39-32 43-36 37-30 I/O Port 0: Port 0 is a bidirectional I/O port. Port 0 is also the multiplexed low-order address and
P1.0-P1.5 3-8 5-9 42-44
P2.0-P2.7 21-28 24-31 18-25 I/O Port 2: Port 2 is an 8-bit bidirectional I/O port. Port 2 emits the high-order address byte
DIP LCC QFP TYPE NAME AND FUNCTION
20 22 16 I Ground: 0V reference.
40 44 38 I Power Supply: This is the power supply voltage for normal, idle, and power-down operation.
data bus during accesses to external program and data memory (see Note 5). In this
application, it uses strong internal pull-ups when emitting 1s. Port 0 also receives code bytes
during parallel EPROM programming and outputs code bytes during verification. External
pull-ups are required during program verification. During reset, the port register is loaded
with 1’s. Port 0 has 4 output modes selected on a per bit basis by writing to the P0M1 and
P0M2 Special Function Registers as follows:
P0M1.x P0M2.x Mode Description
0 0 Open drain (default). See Note 1.
0 1 W eak pullup. See Note 2.
1 0 High impedance. See Note 3.
1 1 Push-pull. See Note 4.
Port 0 is also the data I/O port for the Universal Peripheral Interface (UPI). When the UPI is
enabled, port 0 must be configured as High-Z by the user. Input/Output through P0 is
controlled by pin CS
I/O Port 1: Port 1 is a 6-bit bidirectional I/O port with Schmitt trigger inputs. Port 1 receives the control
1-3
3 4 42 I/O P1.0/ADIN0
4 5 43 I/O P1.1/ADIN1
5 6 44 I/O P1.2/ADIN2
6 7 1 I/O P1.3/ADIN3
7 8 2 I/O P1.4/ADIN4
8 9 3 I/O P1.5/ADIN5
21 24 18 P2.0 CEX0 PCA module 0 external I/O
22 25 19 P2.1 CEX1 PCA module 1 external I/O
23 26 20 P2.2 CEX2 PCA module 2 external I/O
24 27 21 P2.3 CEX3 PCA module 3 external I/O
25 28 22 P2.4 T2EX timer 2 capture input
26 29 23 P2.5 T2 timer 2 external I/O — clock-out (programmable)
27 30 24 P2.6 CEX4 PCA module 4 external I/O
28 31 25 P2.7 ECI PCA count input
signals during program memory verification and parallel EPROM programming. During reset, port
1 is configured as a high impedance analog input port. Digital push-pull outputs are enabled by
writing 1’s to the P1M1 register. The programmer must take care to prevent digital outputs from
switching while an A/D conversion is in progress. Port 1 has 3 output modes selected on a per bit
basis by writing to the P1M1 and P1M2 special function registers as follows:
P1M1.X P1M2.X Mode Description
0 0 A/D only. (High impedance)
0 1 Digital input only. High impedance (default).
1 X Push-pull.
Port 1 pins also serve alternate functions as follows:
during accesses to external program and data memory that use 16-bit addresses (MOVX
@DPTR) (see Note 5). In this application, it uses strong internal pull-ups when emitting 1s.
Port 2 receives the high-order address byte during program verification and parallel EPROM
programming. During reset, the port 2 pullups are turned on synchronously, and the port
register is loaded with 1’s. Port 2 has the following output modes which can be selected on a
per bit basis by writing to P2M1 and P2M0:
P2M1.X P2M2.X Mode Description
0 0 Open drain. See Note 1.
0 1 W eak pullup (default). See Note 2.
1 0 High impedance. See Note 3.
1 1 Push-pull. See Note 4.
Port 2 pins serve alternate functions as follows:
, WR, RD, and A0. Output is push-pull when enabled.
CMP0 comparator 0 output
CMP1 comparator 1 output
CMP2 comparator 2 output
CMP3 comparator 3 output
A0 UPI address input
CS UPI chip select input
PWM0 Pulse width modulator 0 output
PWM1 Pulse width modulator 1 output
83C576/87C576
1998 Jun 04
5
Page 6

Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
PIN DESCRIPTIONS (Continued)
PIN NUMBER
MNEMONIC DIP LCC QFP TYPE NAME AND FUNCTION
+V
/AV
REF
–V
/AV
REF
P3.0-P3.7 10-17 11,
RST 9 10 4 I Reset: A low on this pin synchronously resets all port pins to a high state. The pin must be
ALE/PROG 30 33 27 I/O Address Latch Enable/Program Pulse: Output pulse for latching the low byte of the address
PSEN 29 32 26 O Program Store Enable: The read strobe to external program memory. When the device is
EA/V
PP
XTAL1 19 21 15 I Crystal 1: Input to the inverting oscillator amplifier and input to the internal clock generator
XTAL2 18 20 14 O Crystal 2: Output from the inverting oscillator amplifier.
NOTES:
1. When Open Drain mode is selected, ports 0 and 2 have weak pulldowns to guarantee positive leakage current (see DC electrical
characteristic I
2. When Weak Pullup mode is selected, ports bits that have 1’s written to them can be used as inputs but will source current when externally
pulled low (see DC electrical characteristic IIL).
3. When High Impedance mode is selected, all pullups and pulldowns are turned off. The only current sourced or sunk by the pin is the
parasitic leakage current (see DC electrical characteristic I
4. When Push-Pull mode is selected, strong pullups are on continuously when emitting 1’s (see DC electrical characteristic V
5. When Open-Drain, Weak Pull-up, or Push-pull mode is selected.
1 2 40 I A/D positive power supply
CC
2 3 41 I A/D 0V reference
SS
I/O Port 3: Port 3 is an 8-bit bidirectional I/O port. Port 3 pins that have 1s written to them can
13-195,7-13
be used as inputs but will source current when externally pulled low (see DC Electrical
Characteristics: I
high until written to by software. Port 3 has the following output modes which can be
). During reset all pins will be synchronously driven high and will remain
IL
selected on a per bit basis by writing to P3M1 and P3M2:
P3M1.X P3M2.X Mode Description
0 0 Open drain. See Note 1.
0 1 W eak pullup (default). See Note 2.
1 0 High impedance. See Note 3.
1 1 Push-pull. See Note 4.
Port 3 pins serve alternate functions as follows:
10 11 5 I P3.0 RxD Serial receive port
11 13 7 O P3.1 TxD Serial transmit port (enabled only when transmitting serial data)
12 14 8 I P3.2 INT0 External interrupt 0
CMP3+ Comparator 3 positive input
13 15 9 I P3.3 INT1 External interrupt 1
CMP2+ Comparator 2 positive input
14 16 10 I P3.4 T0 Timer/counter 0 input
CMP1+ Comparator 1 positive input
15 17 11 I P3.5 T1 Timer/counter 1 input
CMPR– Common reference to comparators 1, 2, 3
16 18 12 O P3.6 WR External data memory write strobe
CMP0+ Comparator 0 positive input
17 19 13 O P3.7 RD External data memory read strobe
CMP0– Comparator 0 negative input
held low with the oscillator running for 24 oscillator cycles to initialize the internal registers.
An internal diffused resistor to V
capacitor to V
with a slow rising input voltage.
. RST has a Schmitt trigger input stage to provide additional noise immunity
SS
permits a power on reset using only an external
CC
during an access to external memory. In normal operation, ALE is emitted at a constant rate
of 1/6 the oscillator frequency, and can be used for external timing or clocking. Note that
one ALE pulse is skipped during each access to external data memory. ALE is switched off
if the bit 0 in the AUXR register (8EH) is set. This pin is also the program pulse input
(PROG
) during parallel EPROM programming. (See also I n t e r n a l Re s e t o n pa g e 2 4. )
executing code from the external program memory, PSEN
cycle, except that two PSEN
memory. PSEN
is not activated during fetches from internal program memory.
activations are skipped during each access to external data
31 35 29 I External Access Enable/Programming Supply Voltage: EA must be externally held low
to enable the device to fetch code from external program memory locations 0000H to
1FFFH. If EA
is held high, the device executes from internal program memory unless the
program counter contains an address greater than 1FFFH. This pin also receives the
12.75V programming supply voltage (V
voltage during reset the device enters the in-circuit programming mode.
) during EPROM programming. If this pin is at V
PP
circuits.
).
IH
or ILC, as applicable.
L2
83C576/87C576
is activated twice each machine
).
OH
PP
1998 Jun 04
6
Page 7
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
Table 1. 87C576 Special Function Registers
SYMBOL DESCRIPTION
ACC* Accumulator E0H E7 E6 E5 E4 E3 E2 E1 E0 00H
ADC0H# A/D Channel 0 MSB AAH 00H
ADC1H# A/D Channel 1 MSB ABH 00H
ADC2H# A/D Channel 2 MSB ACH 00H
ADC3H# A/D Channel 3 MSB ADH 00H
ADC4H# A/D Channel 4 MSB AEH 00H
ADC5H# A/D Channel 5 MSB AFH 00H
ADC0L# A/D Channel 0 2-LSBits 9AH 00H
ADC1L# A/D Channel 1 2-LSBits 9BH 00H
ADC2L# A/D Channel 2 2-LSBits 9CH 00H
ADC3L# A/D Channel 3 2-LSBits 9DH 00H
ADC4L# A/D Channel 4 2-LSBits 9EH 00H
ADC5L# A/D Channel 5 2-LSBits 9FH 00H
ADCON# A/D Control B1H ADF ADCE AD8M
ADCS# A/D Channel Select B2H 00H
DIRECT
ADDRESS
BIT ADDRESS, SYMBOL, OR ALTERNATIVE PORT FUNCTION
MSB LSB
AMOD1
AMOD0
ASCA2 ASCA1
83C576/87C576
RESET
VALUE
ASCA0 00H
AUXR# Auxiliary 8EH – – – – SRST TXI LO AO xxxx0000B
B* B register F0H F7 F6 F5 F4 F3 F2 F1 F0 00H
CCAP0H# Module 0 Capture High FAH xxxxxxxxB
CCAP1H# Module 1 Capture High FBH xxxxxxxxB
CCAP2H# Module 2 Capture High FCH xxxxxxxxB
CCAP3H# Module 3 Capture High FDH xxxxxxxxB
CCAP4H# Module 4 Capture High FEH xxxxxxxxB
CCAP0L# Module 0 Capture Low EAH xxxxxxxxB
CCAP1L# Module 1 Capture Low EBH xxxxxxxxB
CCAP2L# Module 2 Capture Low ECH xxxxxxxxB
CCAP3L# Module 3 Capture Low EDH xxxxxxxxB
CCAP4L# Module 4 Capture Low EEH xxxxxxxxB
CCAPM0# Module 0 Mode DAH – ECOM CAPP CAPN MAT TOG PWM ECCF x0000000B
CCAPM1# Module 1 Mode DBH – ECOM CAPP CAPN MAT TOG PWM ECCF x0000000B
CCAPM2# Module 2 Mode DCH – ECOM CAPP CAPN MAT TOG PWM ECCF x0000000B
CCAPM3# Module 3 Mode DDH – ECOM CAPP CAPN MAT TOG PWM ECCF x0000000B
CCAPM4# Module 4 Mode DEH – ECOM CAPP CAPN MAT TOG PWM ECCF x0000000B
DF DE DD DC DB DA D9 D8
CCON*# PCA Counter Control D8H CF CR – CCF4 CCF3 CCF2 CCF1 CCF0 00x00000B
CH# PCA Counter High F9H 00H
CL# PCA Counter Low E9H 00H
CMOD# PCA Counter Mode D9H CIDL WDTE – – – CPS1 CPS0 ECF 00xxx000B
C7 C6 C5 C4 C3 C2 C1 C0
CMP*# Comparator C0H EC3DP EC2DP EC1DP EC0DP C3RO C2RO C1RO C0RO 00H
CMPE# Comparator Enable 92H
DPTR: Data Pointer (2 bytes)
DPH Data Pointer High 83H 00H
DPL Data Pointer Low 82H 00H
IE0*# Interrupt Enable 0 A8H EA EC ET2 ES ET1 EX1 ET0 EX0 00H
IE1*# Interrupt Enable 1 E8H EOB EIB EAD EC4 EC3 EC2 EC1 EC0 00H
* SFRs are bit addressable.
# SFRs are modified from or added to the 80C51 SFRs.
EC3TDC EC2TDC EC1TDC EC0TDC
AF AE AD AC AB AA A9 A8
EC3O EC2O EC1O EC0O 00H
1998 Jun 04
7
Page 8
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
Table 1. 87C576 Special Function Registers (Continued)
SYMBOL DESCRIPTION
IP0* Interrupt Priority 0 B8H – PPC PT2 PS PT1 PX1 PT0 PX0 x0000000B
IP1*# Interrupt Priority 1 F8H POB PIB PAD PC4 PC3 PC2 PC1 PC0 00H
P0* Port 0 80H AD7 AD6 AD5 AD4 AD3 AD2 AD1 AD0 FFH
P1* Port 1 90H – – ADIN5 ADIN4 ADIN3 ADIN2 ADIN1 ADIN0 FFH
P2* Port 2 A0H ECI CEX4 T2 T2EX CEX3 CEX2 CEX1 CEX0 FFH
P3* Port 3 B0H RD WR T1 T0 INT1 INT0 TxD RxD FFH
P0M1# Port 0 Output Mode 1 84H 00H
P0M2# Port 0 Output Mode 2 85H 00H
P1M1# Port 1 Output Mode 1 94H 00H
P1M2# Port 1 Output Mode 2 95H 3FH
P2M1# Port 2 Output Mode 1 A4H 00H
P2M2# Port 2 Output Mode 2 A5H FFH
P3M1# Port 3 Output Mode 1 B4H 00H
P3M2# Port 3 Output Mode 2 B5H FFH
PCON Power Control 87H
PSW* Program Status Word D0H CY AC F0 RS1 RS0 OV – P 00H
PWCON# PWM Control BCH – – – – PWMF
PWMP# PWM Prescaler BDH 00H
PWM0# PWM Register 0 BEH 00H
PWM1# PWM Register 1 BFH 00H
RACAP2H#
RACAP2L#
Timer 2 Capture High CBH 00H
Timer 2 Capture Low CAH 00H
DIRECT
ADDRESS
BIT ADDRESS, SYMBOL, OR ALTERNATIVE PORT FUNCTION
MSB LSB
BF BE BD BC BB BA B9 B8
87 86 85 84 83 82 81 80
97 96 95 94 93 92 91 90
A7 A6 A5 A4 A3 A2 A1 A0
B7 B6 B5 B4 B3 B2 B1 B0
1
SMOD1
SMOD0
D7 D6 D5 D4 D3 D2 D1 D0
OSF1POF1LVF
WDT0F
EN/CLR
83C576/87C576
1
PD IDL 00xxxx00B
PWE1 PWE0 00H
RESET
VALUE
SADDR# Slave Address A9H 00H
SADEN# Slave Address Mask B9H 00H
SBUF Serial Data Buffer 99H xxxxxxxxB
9F 9E 9D 9C 9B 9A 99 98
SCON* Serial Control 98H
SP Stack Pointer 81H 07H
TCON* Timer Control 88H TF1 TR1 TF0 TR0 IE1 IT1 IE0 IT0 00H
T2CON* Timer 2 Control C8H TF2 EXF2 RCLK TCLK EXEN2 TR2 C/T2 CP/RL2 00H
T2MOD# Timer 2 Mode Control C9H – – – – – – T2OE2DCEN xxxxxxx0B
* SFRs are bit addressable.
# SFRs are modified from or added to the 80C51 SFRs.
1. Reset value depends on reset source.
2. Programmable clock-out
1998 Jun 04
SM0/FE
8F 8E 8D 8C 8B 8A 89 88
CF CE CD CC CB CA C9 C8
SM1 SM2 REN TB8 RB8 TI RI 00H
8
Page 9
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
Table 1. 87C576 Special Function Registers (Continued)
SYMBOL DESCRIPTION
TH0 Timer High 0 8CH 00H
TH1 Timer High 1 8DH 00H
TH2# Timer High 2 CDH 00H
TL0 Timer Low 0 8AH 00H
TL1 Timer Low 1 8BH 00H
TL2# Timer Low 2 CCH 00H
TMOD Timer Mode 89H GATE C/T M1 M0 GATE C/T M1 M0 00H
UCS# UPI Control/Status 86H
DIRECT
ADDRESS
BIT ADDRESS, SYMBOL, OR ALTERNATIVE PORT FUNCTION
MSB LSB
ST7 ST6 ST5 ST4 UE AF IBF
83C576/87C576
RESET
VALUE
OBE/OBF
00H
WDCON#Watchdog Timer Control
WDL#
WFEED1# Watchdog Feed 1 C2H xxH
WFEED2# Watchdog Feed 2 C3H xxH
* SFRs are bit addressable.
# SFRs are modified from or added to the 80C51 SFRs.
1. Reset value depends on reset source.
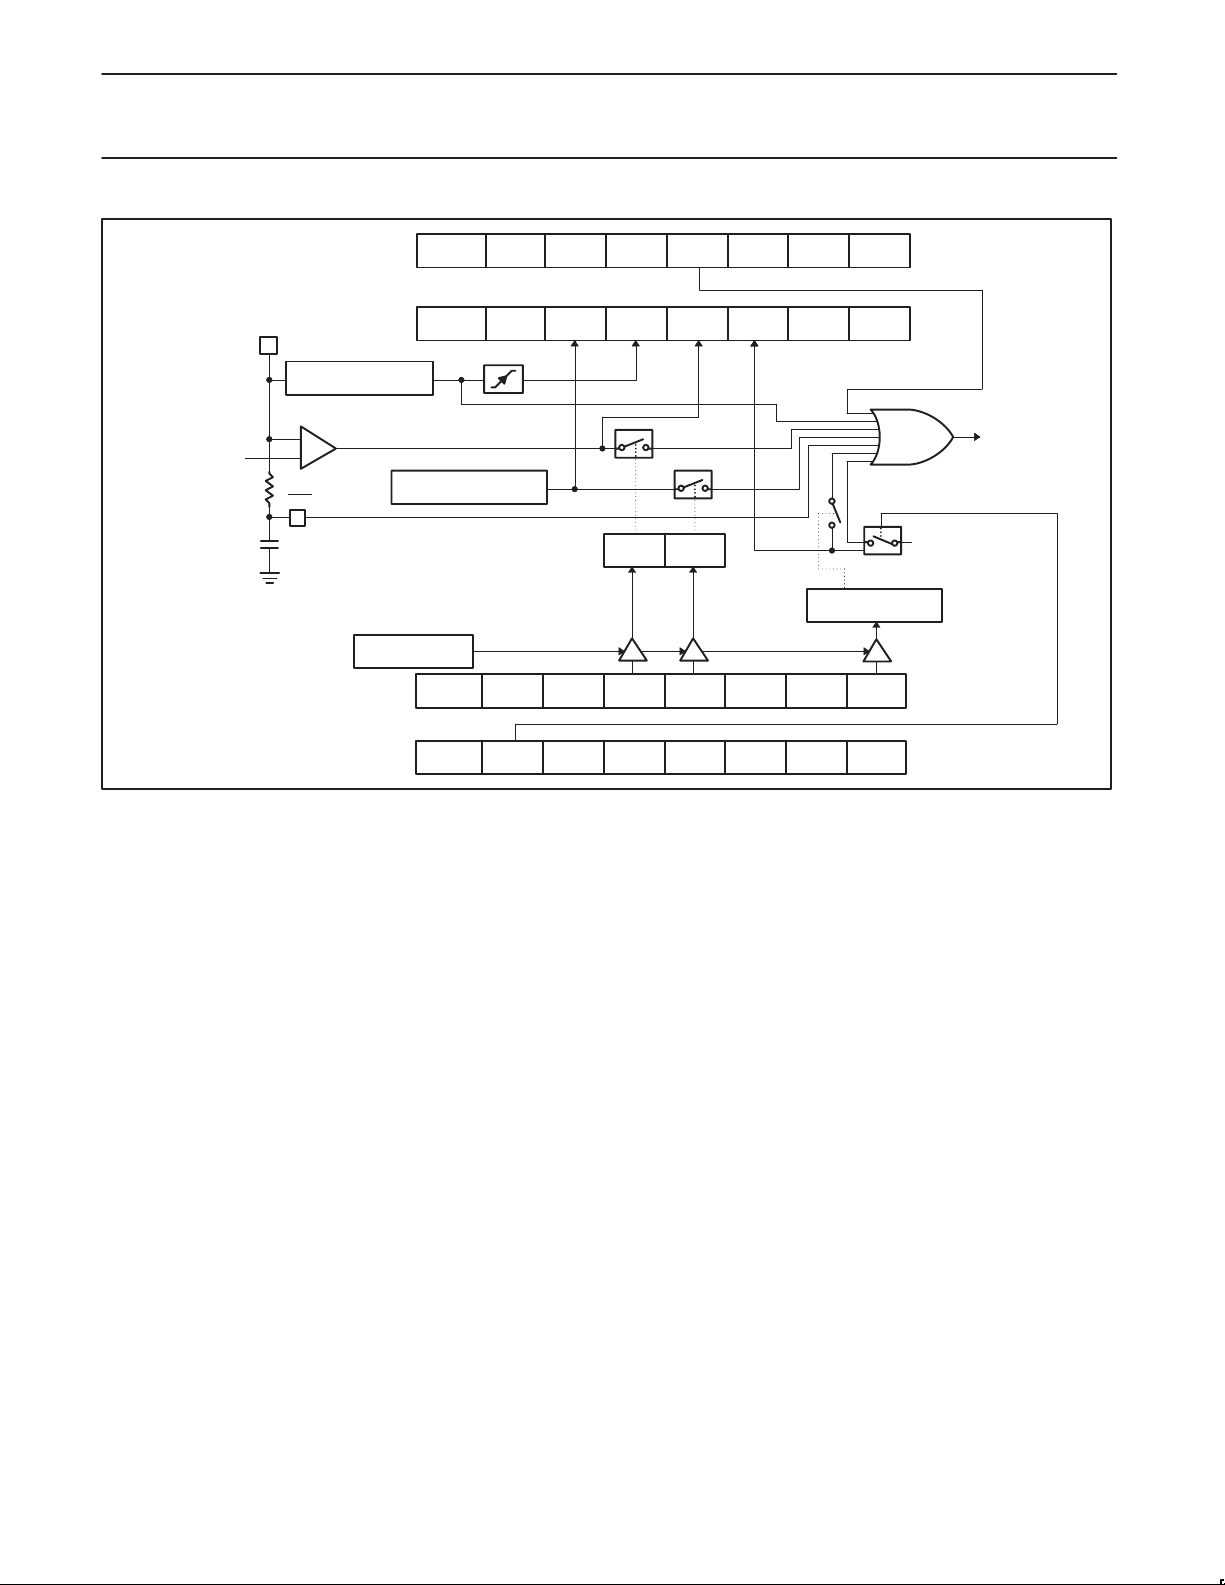
The 8XC576 has a number of failure detect circuits to prevent
abnormal operating conditions. these failure detect circuits generate
resets as shown in Figure 1.
Watchdog Timer Reload
POWER ON CLEAR / POWER ON FLAG
An on-chip Power On Detect Circuit resets the 8XC576 and sets the
Power Off Flag (PCON.4) on power up or if V
momentarily. The POF can only be cleared by software. The RST
pin is not driven by the power on detect circuit. The POF can be
read by software to determine that a power failure has occurred and
can also be set by software.
LOW VOLTAGE DETECT
An on-chip Low Voltage Detect circuit sets the Low Voltage Flag
(PCON.3) if V
Characteristics) and resets the 8XC576 if the Low Voltage Reset
Enable bit (WDCON.4) is set. If the LVRE is cleared, the reset is
disabled but LVF will still be set if V
driven by the low voltage detect circuit. The LVF can be read by
software to determine that V
cleared by software.
drops below V
CC
LOW
was low. The LVF can be set or
CC
OSCILLATOR FAIL DETECT
An on-chip Oscillator Fail Detect circuit sets the Oscillator Fail Flag
(PCON.5) if the oscillator frequency drops below OSCF for one or
more cycles (see AC Electrical Characteristics: OSCF) and resets
the 8XC576 if the Oscillator Fail Reset Enable bit (WDCON.3) is set.
If OFRE is cleared, the reset is disabled but OSF will still be set if
the oscillator fails. The RST pin is not driven by the oscillator fail
detect circuit. The OSF can be read by software to determine that
an oscillator failure has occurred. The OSF can be set or cleared by
software.
C4H PRE2 PRE1 PRE0 LVRE OFRE DPD
C1H 00H
LOW ACTIVE RESET
One of the most notable features on this part is the low active reset.
The low active reset operates exactly the same as high active reset
with the exception that the part is put into the reset mode by
applying a low level to the reset pin. For power-on reset it is also
necessary to invert the power-on reset circuit; connecting the 8.2K
resistor from the reset pin to V
drops to zero
CC
(see DC Electrical
is low. The RST pin is not
CC
reset pin to ground. Figure 1 shows the reset related circuitry.
When reset the port pins on the 8XC576 are driven high
synchronously.
The 8XC576 also has Low voltage detection circuitry that will, if
enabled, force the part to reset when V
set level. Low Voltage Reset is enabled by a normal reset. Low
Voltage Reset can be disabled by clearing LVRE (bit 4 in the
WDCON SFR) then executing a watchdog feed sequence (A5H to
WFEED1 followed immediately by 5AH to WFEED2). In addition
there is a flag (LVF) that is set if a low voltage condition is detected.
The LVF flag is set even if the Low Voltage detection circuitry is
disabled. Notice that the Low voltage detection circuitry does not
drive the RST# pin so the LVF flag is the only way that the
microcontroller can determine if it has been reset due to a low
voltage condition.
The 8XC576 has an on-chip power-on detection circuit that sets the
POF (PCON.4) flag on power up or if the V
drops to 0V . This flag can be used to determine if the part is being
started from a power-on (cold start) or if a reset has occurred due to
another condition (warm start).
The 8XC576 can be reset in software by setting the RST bit of the
AUXR register (AUXR.3). See Figure 1 for reset diagram.
WDRUN
and the 10µf capacitor from the
CC
WDMOD
(on the part) fails below a
CC
level momentarily
CC
11111111B
1998 Jun 04
9
Page 10
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
VLOW
(LOW V
CC
REFERENCE)
– – – SRST TXI LO AO
V
CC
POWER-ON DETECT
+
–
RST
WATCHDOG FEED
SMOD1 SMOD0 OSF LVF WDTOF PD IDL
OSC FREQ BELOW OSCF
(MIN FREQUENCY)
SHADOW REGISTER
FOR WDCON
PRE2 PRE1 PRE0 LVRE OFRE DPD WDRUN WDMOD
CIDL WDTE – – – CPS1 CPS0 ECF
–
POF
SHADOW REGISTER
AUXR
(8EH)
PCON
(87H)
8xC576
INTERNAL
RESET
WDTE
PCA WATCHDOG
WATCHDOG TIMER
WDCON
(C4H)
CMOD
(D9H)
SU00515B
Figure 1. Reset Circuitry
TIMERS
The 8XC576 has four on-chip timers.
Timers 0 and 1 are identical in every way to Timers 0 and 1 on the
80C51.
Timer 2 on the 8XC576 is identical to the 80C52 Timer 2 (described
in detail in the 80C52 overview) with the exception that it is an up or
down counter. To configure the Timer to count down the DCEN bit in
the T2MOD special function register must be set and a low level
must be present on the T2EX pin (P1.1).
The Pulse Width Modulator (PWM) system can be used as a timer
by disabling its outputs and monitoring its counter overflow flag, the
PWMF bit in the PWCON register (see the PWM section for details).
The Watchdog timer operation and implementation is similar to the
8XC550 (for additional information see the 8XC550 datasheet) with
the exception that the reset values of the WDCON and WDL special
function registers have been changed. The changes in these
registers cause the watchdog timer to be enabled with a timeout of
16384 × T
when the part is reset. The watchdog can be disabled
OSC
by executing a valid feed sequence and then clearing WDRUN (bit 2
in the WDCON SFR). In timer mode, the timer is controlled by
toggling the WDRUN bit. The timeout flag, WDTOF, is set when the
timer overflows and must be cleared in software.
PROGRAMMABLE COUNTER ARRAY (PCA)
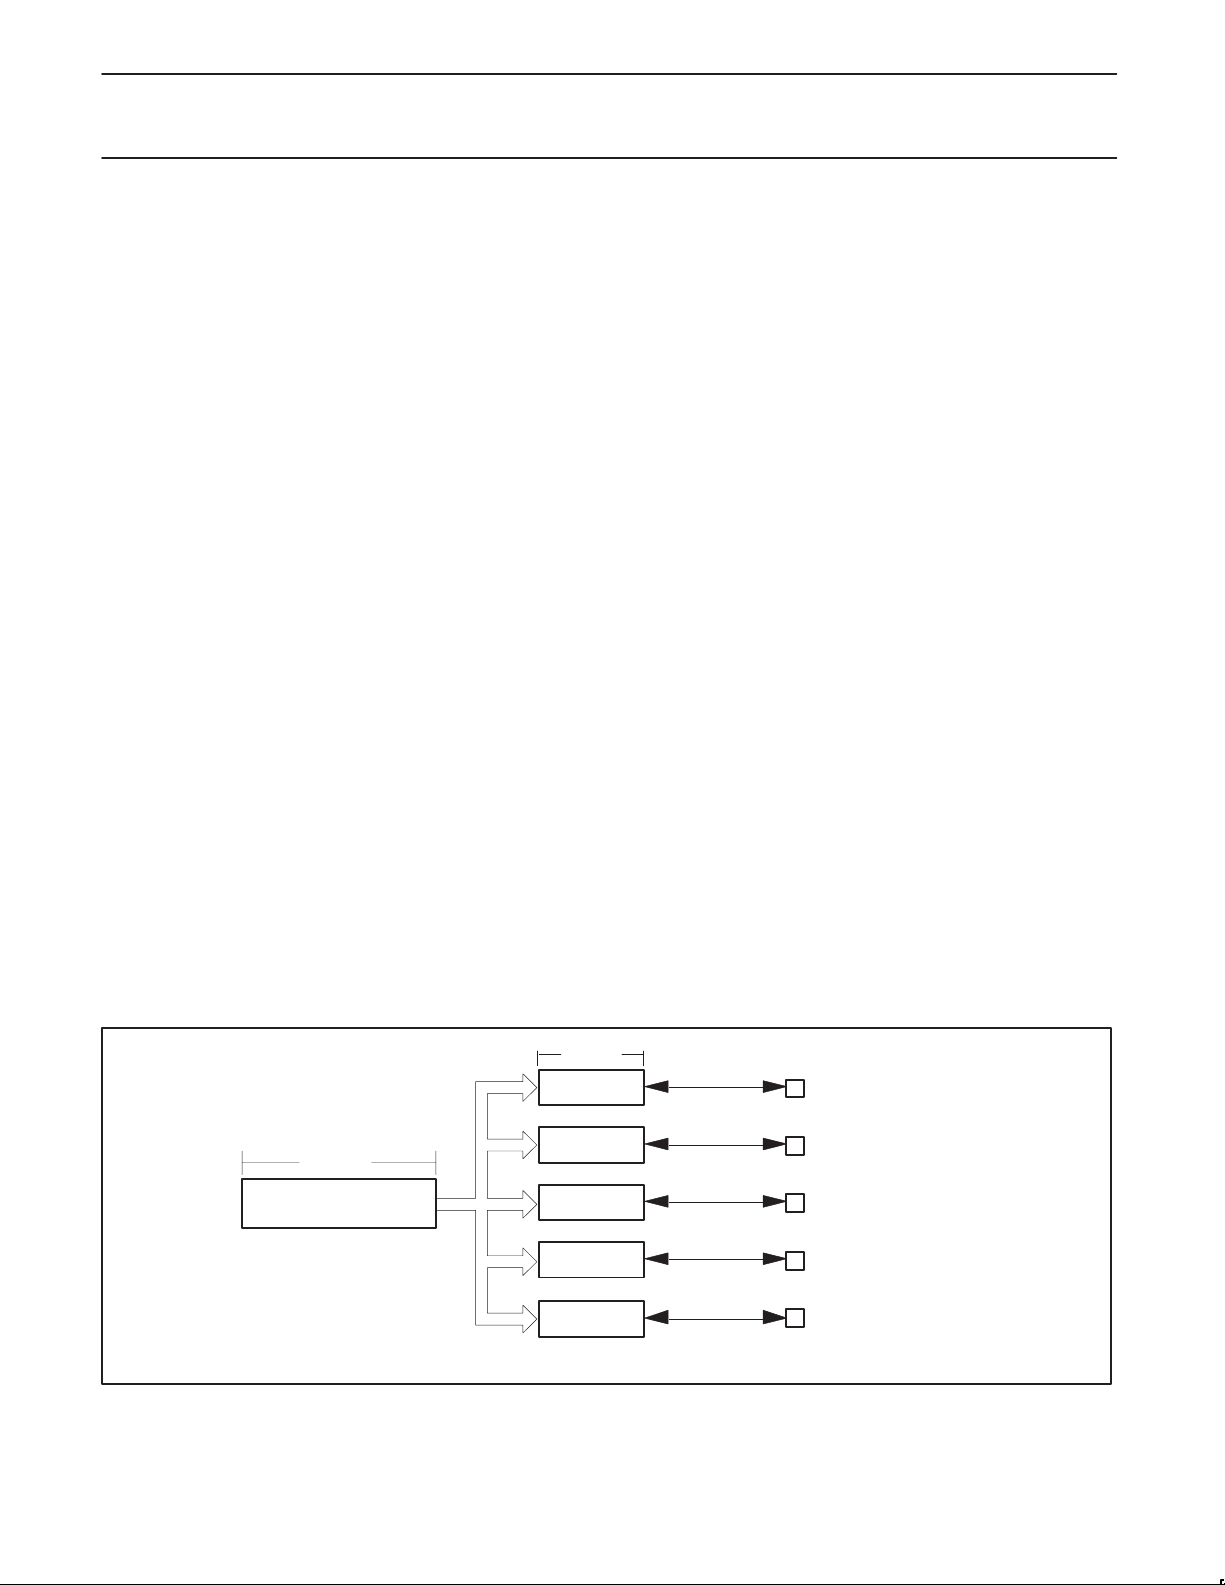
The Programmable Counter Array is a special Timer that has five
16-bit capture/compare modules associated with it. Each of the
modules can be programmed to operate in one of four modes: rising
and/or falling edge capture, software timer, high-speed output, or
pulse width modulator . Each module has a pin associated with it in
port 2. Module 0 is connected to P2.0(CEX0), module 1 to
P2.1(CEX1), etc. The basic PCA configuration is shown in Figure 2.
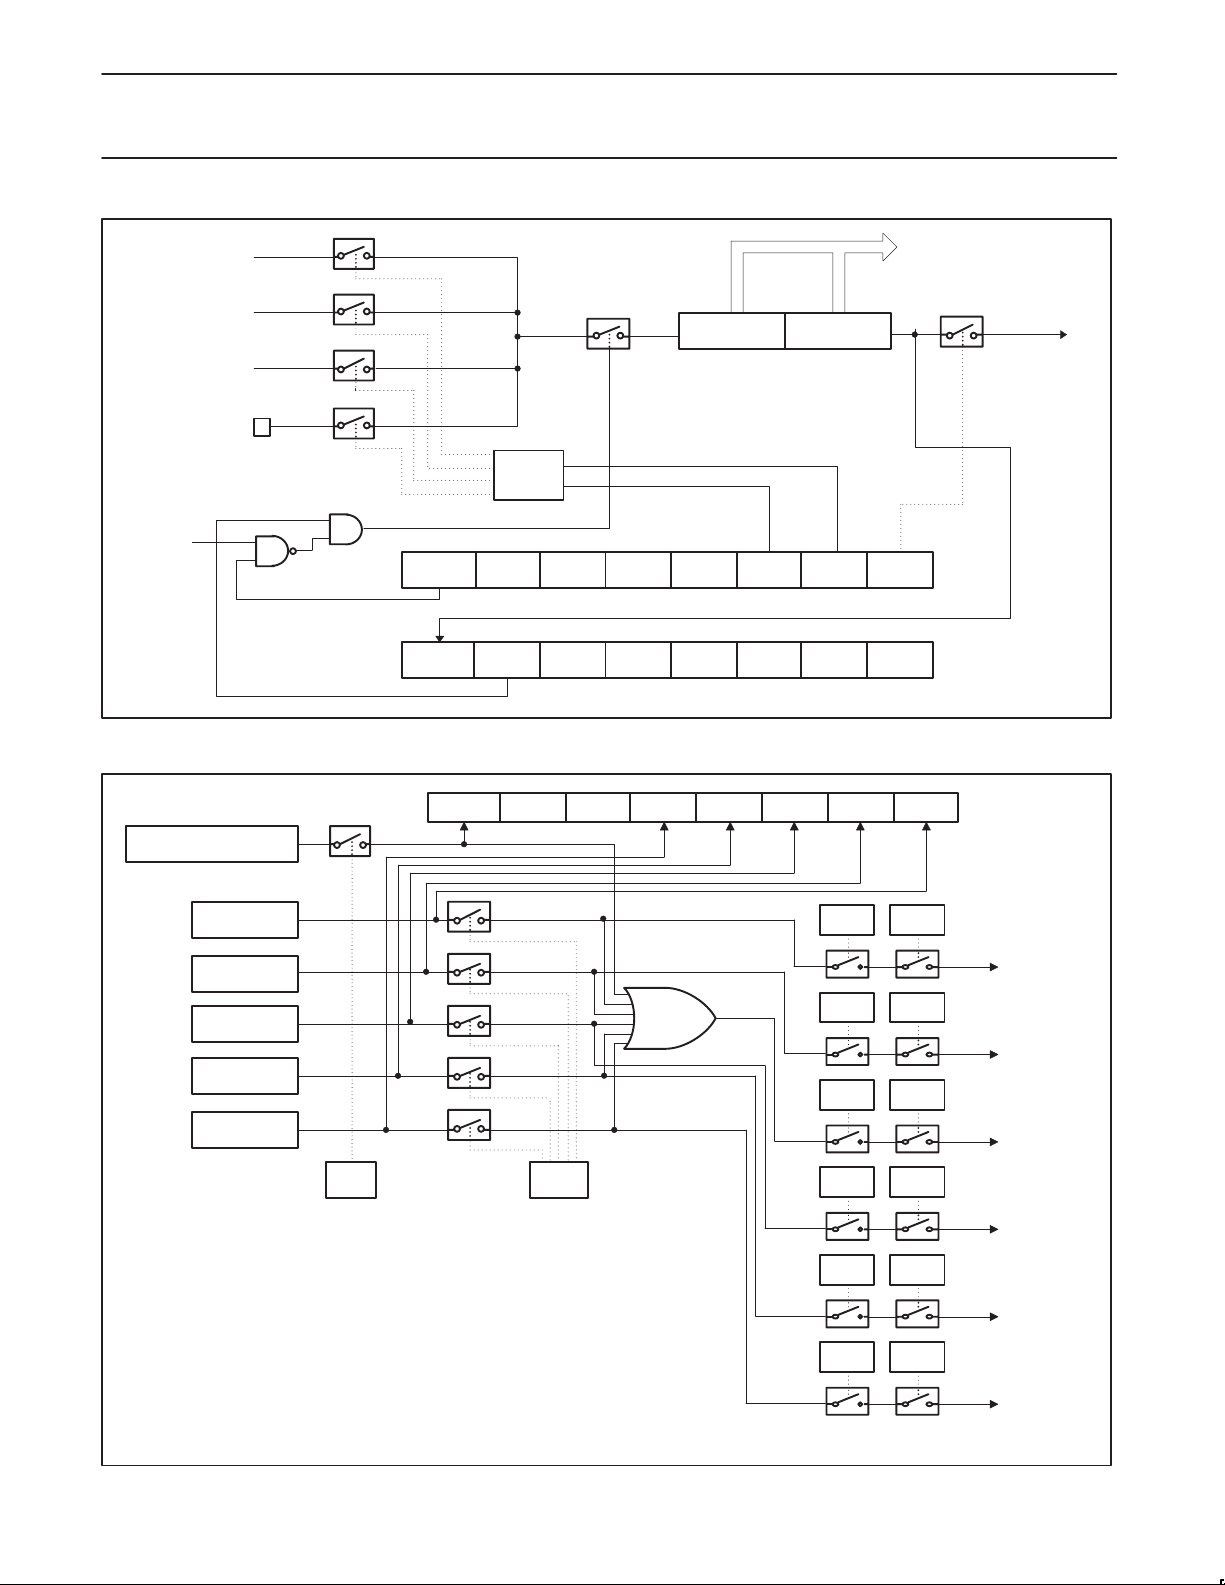
The PCA timer is a common time base for all five modules and can
be programmed to run at: 1/12 the oscillator frequency, 1/4 the
oscillator frequency , the Timer 0 overflow, or the input on the ECI pin
(P2.7). The timer count source is determined from the CPS1 and
CPS0 bits in the CMOD SFR as follows (see Figure 3):
CPS1 CPS0 PCA Timer Count Source
0 0 1/12 oscillator frequency
0 1 1/4 oscillator frequency
1 0 Timer 0 overflow
1 1 External Input at ECI pin (P2.7)
In the CMOD SFR are three additional bits associated with the PCA.
They are CIDL which allows the PCA to stop during idle mode,
WDTE which enables or disables the watchdog function on
module 4, and ECF which when set causes an interrupt and the
PCA overflow flag CF (in the CCON SFR) to be set when the PCA
timer overflows. These functions are shown in Figure 3.
The watchdog timer function is implemented in module 4 as
implemented in other parts that have a PCA that are available on the
market. However, if a watchdog timer is required in the target
application, it is recommended to use the hardware watchdog timer
that is implemented on the 87C576 separately from the PCA (see
Figure 15).
The CCON SFR contains the run control bit for the PCA and the
flags for the PCA timer (CF) and each module (refer to Figure 6). To
run the PCA the CR bit (CCON.6) must be set by software. The
PCA is shut off by clearing this bit. The CF bit (CCON.7) is set when
the PCA counter overflows and an interrupt will be generated if the
ECF bit in the CMOD register is set, The CF bit can only be cleared
by software. Bits 0 through 4 of the CCON register are the flags for
the modules (bit 0 for module 0, bit 1 for module 1, etc.) and are set
by hardware when either a match or a capture occurs. These flags
1998 Jun 04
10
Page 11
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
also can only be cleared by software. The PCA interrupt system
shown in Figure 4.
Each module in the PCA has a special function register associated
with it. These registers are: CCAPM0 for module 0, CCAPM1 for
module 1, etc. (see Figure 7). The registers contain the bits that
control the mode that each module will operate in. The ECCF bit
(CCAPMn.0 where n=0, 1, 2, 3, or 4 depending on the module)
enables the CCF flag in the CCON SFR to generate an interrupt
when a match or compare occurs in the associated module. PWM
(CCAPMn.1) enables the pulse width modulation mode. The TOG
bit (CCAPMn.2) when set causes the CEX output associated with
the module to toggle when there is a match between the PCA
counter and the module’s capture/compare register. The match bit
MAT (CCAPMn.3) when set will cause the CCFn bit in the CCON
register to be set when there is a match between the PCA counter
and the module’s capture/compare register.
The next two bits CAPN (CCAPMn.4) and CAPP (CCAPMn.5)
determine the edge that a capture input will be active on. The CAPN
bit enables the negative edge, and the CAPP bit enables the
positive edge. If both bits are set both edges will be enabled and a
capture will occur for either transition. The last bit in the register
ECOM (CCAPMn.6) when set enables the comparator function.
Figure 8 shows the CCAPMn settings for the various PCA functions.
There are two additional registers associated with each of the PCA
modules. They are CCAPnH and CCAPnL and these are the
registers that store the 16-bit count when a capture occurs or a
compare should occur. When a module is used in the PWM mode
these registers are used to control the duty cycle of the output.
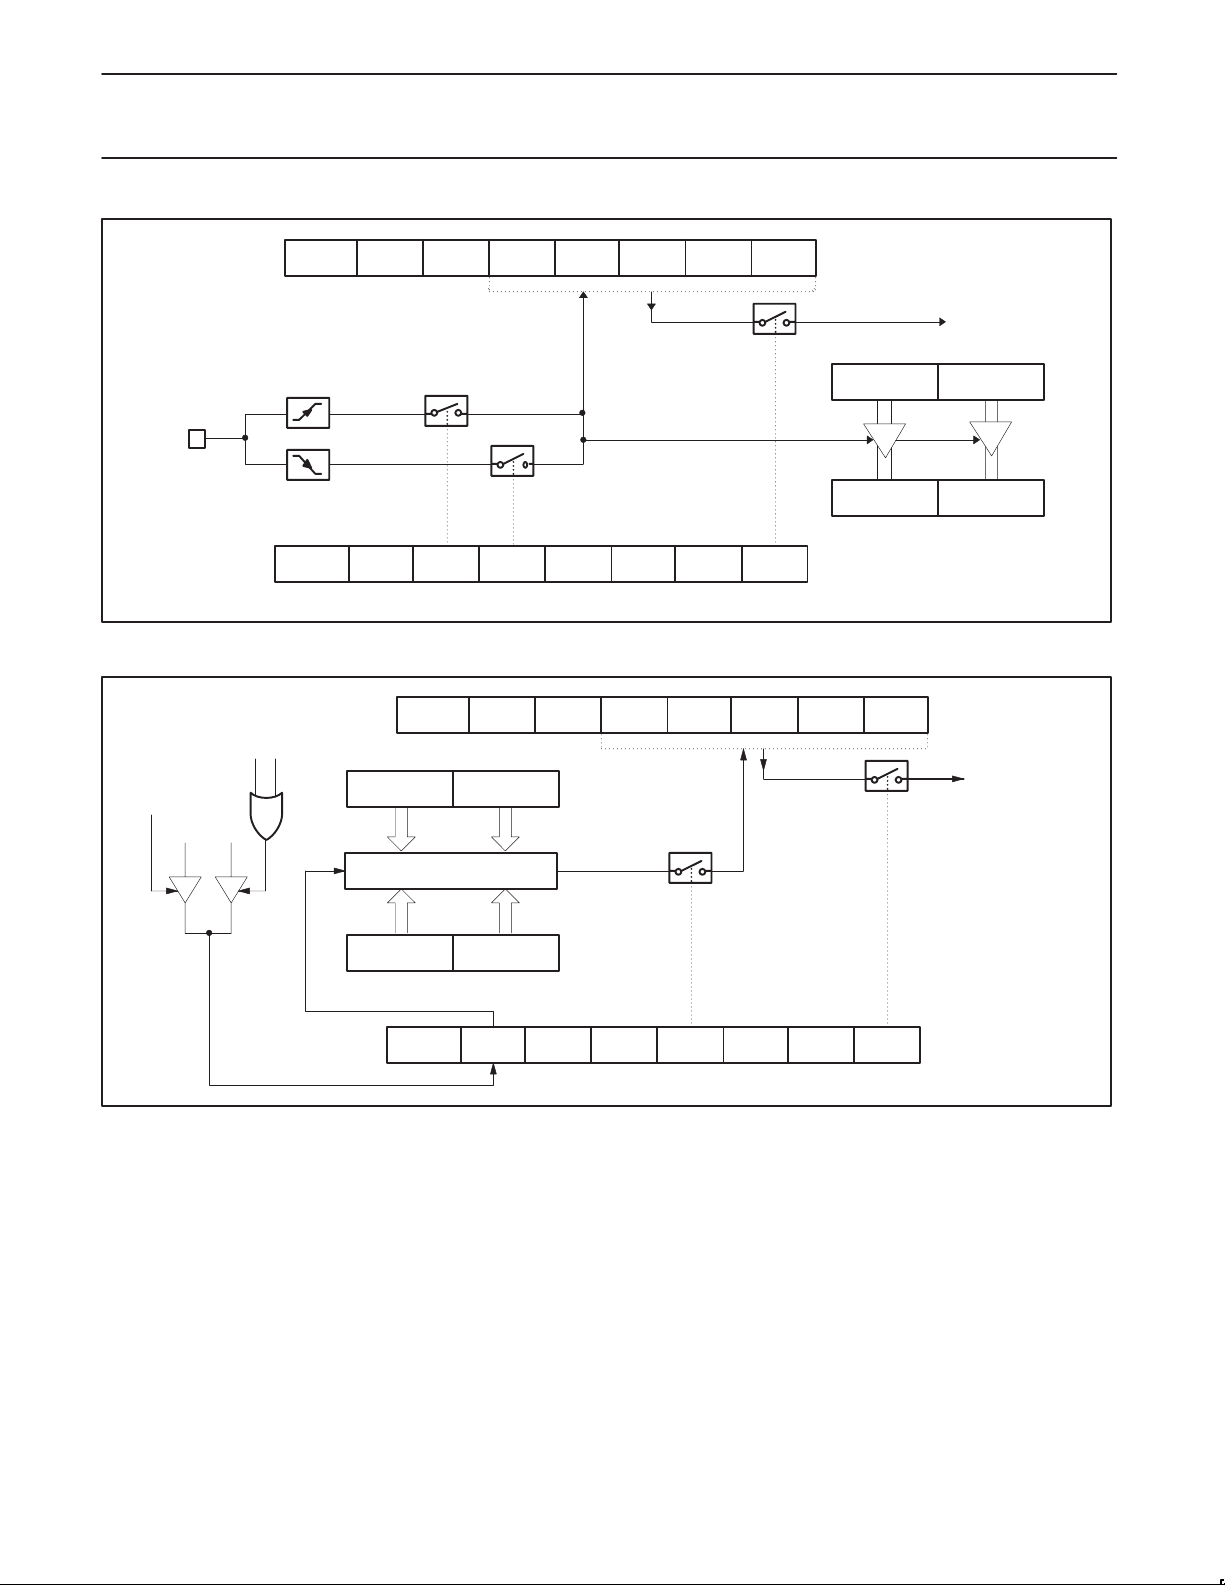
PCA Capture Mode
To use one of the PCA modules in the capture mode either one or
both of the CCAPM bits CAPN and CAPP for that module must be
set. The external CEX input for the module (on port 2) is sampled for
a transition. When a valid transition occurs the PCA hardware loads
the value of the PCA counter registers (CH and CL) into the
module’s capture registers (CCAPnL and CCAPnH). If the CCFn bit
for the module in the CCON SFR and the ECCFn bit in the CCAPMn
SFR are set then an interrupt will be generated. Refer to Figure 9.
16-bit Software Timer Mode
The PCA modules can be used as software timers by setting both
the ECOM and MAT bits in the modules CCAPMn register. The PCA
timer will be compared to the module’s capture registers and when a
match occurs an interrupt will occur if the CCFn (CCON SFR) and
the ECCFn (CCAPMn SFR) bits for the module are both set (see
Figure 10).
High Speed Output Mode
In this mode the CEX output (on port 2) associated with the PCA
module will toggle each time a match occurs between the PCA
counter and the module’s capture registers. To activate this mode
the TOG, MAT, and ECOM bits in the module’s CCAPMn SFR must
be set (see Figure 11).
Pulse Width Modulator Mode
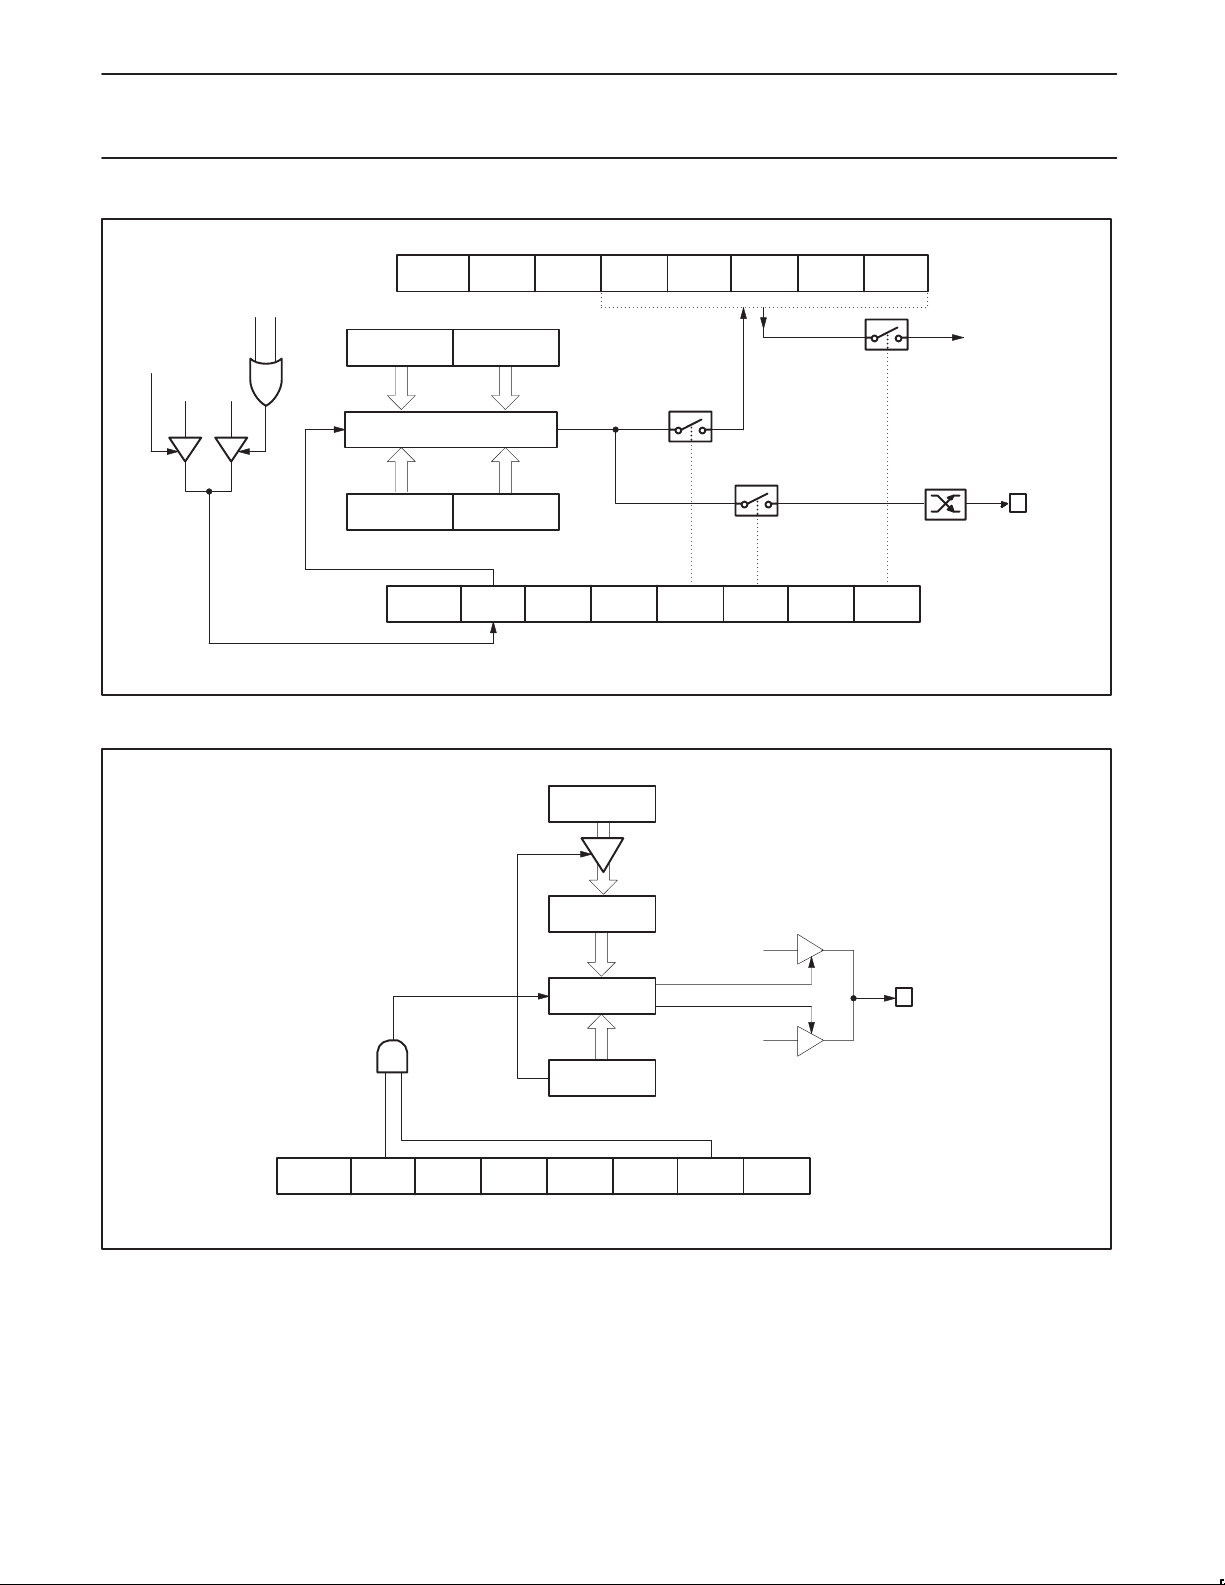
All of the PCA modules can be used as PWM outputs. Figure 12
shows the PWM function. The frequency of the output depends on
the source for the PCA timer. All of the modules will have the same
frequency of output because they all share the PCA timer. The duty
cycle of each module is independently variable using the module’s
capture register CCAPLn. When the value of the PCA CL SFR is
less than the value in the module’s CCAPLn SFR the output will be
low, when it is equal to or greater than the output will be high. When
CL overflows from FF to 00, CCAPLn is reloaded with the value in
CCAPHn. the allows updating the PWM without glitches. The PWM
and ECOM bits in the module’s CCAPMn register must be set to
enable the PWM mode.
PCA Interrupt System
The PCA on most 80C51 family devices provides a single interrupt
source, EC (IE.6). The 8xC576 expands the flexibility of the PCA by
providing additional interrupt sources for each of the five PCA
modules, EC0 (IE1.0) through EC4 (IE1.4), in addition to the original
interrupt source EC (IE.6). Any of these sources can be enabled at
any time. It is possible for both a module source (EC0 through EC4)
to be enabled at the same time that the single source, EC, is
enabled. In this case, a module event will generate an interrupt for
both the module source and the single source, EC.
MODULE FUNCTIONS:
16-BIT CAPTURE
16-BIT TIMER
16-BIT HIGH SPEED OUTPUT
8-BIT PWM
WATCHDOG TIMER (MODULE 4 ONLY)
1998 Jun 04
16 BITS
PCA TIMER/COUNTER
TIME BASE FOR PCA MODULES
16 BITS
MODULE 0
MODULE 1
MODULE 2
MODULE 3
MODULE 4
Figure 2. Programmable Counter Array (PCA)
11
P2.0/CEX0
P2.1/CEX1
P2.2/CEX2
P2.3/CEX3
P2.6/CEX4
SU00578
Page 12
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
OSC/12
83C576/87C576
TO PCA
MODULES
OSC/4
TIMER 0
OVERFLOW
EXTERNAL INPUT
(P2.7/ECI)
IDLE
PCA TIMER/COUNTER
OVERFLOW
CH CL
16–BIT UP COUNTER
00
01
10
DECODE
11
CIDL WDTE –– –– –– CPS1 CPS0 ECF
CF CR CCF4 CCF3 CCF2 CCF1 CCF0––
Figure 3. PCA Timer/Counter
CF CR CCF4 CCF3 CCF2 CCF1 CCF0––
CMOD
(D9H)
CCON
(D8H)
CCON
(D8H)
INTERRUPT
SU00516
MODULE 0
MODULE 1
MODULE 2
MODULE 3
MODULE 4
CMOD.0 ECF
CCAPMn.0 ECCFn
Figure 4. PCA Interrupt System
IE1.0
EC0
IE1.1
EC1
IE0.6
EC
IE1.2
EC2
IE1.3
EC3
IE1.4
EC4
IE0.7
EA
IE0.7
EA
IE0.7
EA
IE0.7
EA
IE0.7
EA
IE0.7
EA
TO
INTERRUPT
PRIORITY
DECODER
TO
INTERRUPT
PRIORITY
DECODER
TO
INTERRUPT
PRIORITY
DECODER
TO
INTERRUPT
PRIORITY
DECODER
TO
INTERRUPT
PRIORITY
DECODER
TO
INTERRUPT
PRIORITY
DECODER
SU00579
1998 Jun 04
12
Page 13
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
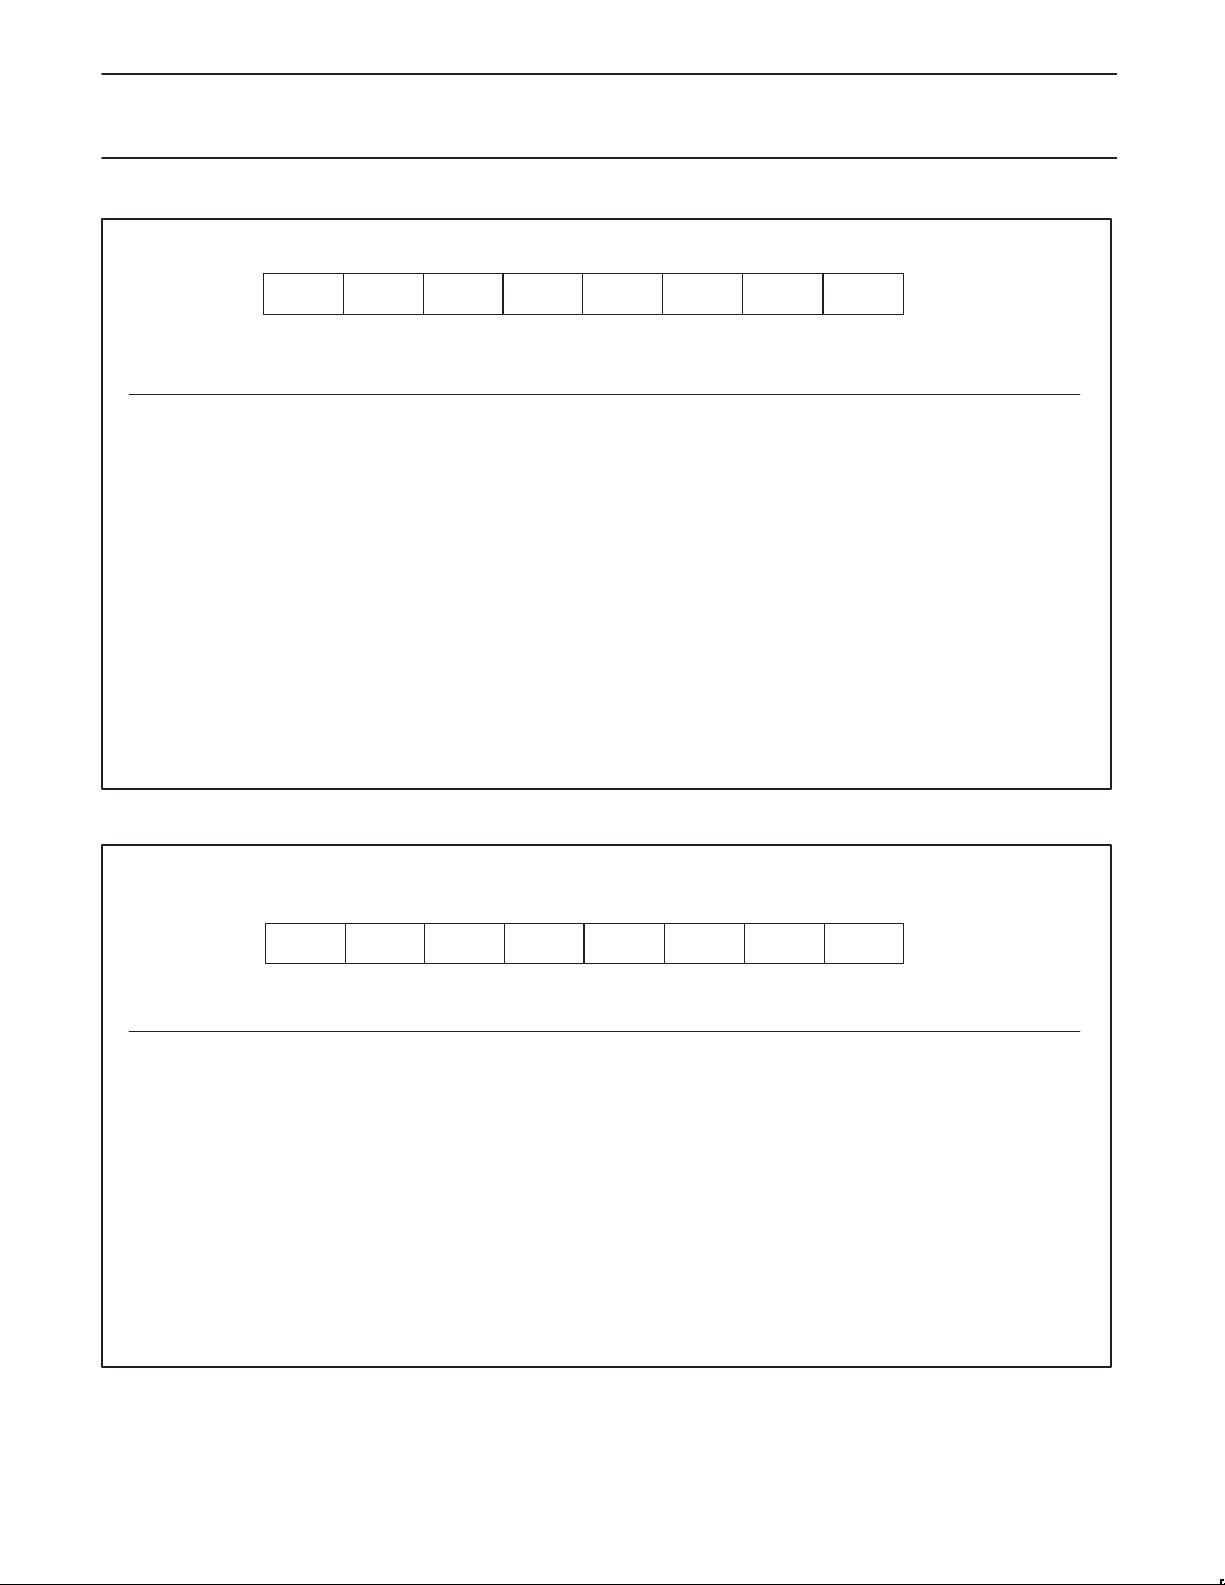
CMOD Address = OD9H
Reset Value = 00XX X000B
CIDL WDTE – – – CPS1 CPS0 ECF
Bit:
76543210
Symbol Function
CIDL Counter Idle control: CIDL = 0 programs the PCA Counter to continue functioning during idle Mode.
CIDL = 1 programs it to be gated off during idle.
WDTE Watchdog Timer Enable: WDTE = 0 disables Watchdog Timer function on PCA Module 4. WDTE = 1 enables it.
– Not implemented, reserved for future use.*
CPS1 PCA Count Pulse Select bit 1.
CPS0 PCA Count Pulse Select bit 0.
CPS1 CPS0 Selected PCA Input**
0 0 0 Internal clock, f
0 1 1 Internal clock, f
OSC
OSC
÷ 12
÷ 4
1 0 2 Timer 0 overflow
1 1 3 External clock at ECI/P2.7 pin (max. rate = f
OSC
÷ 8)
ECF PCA Enable Counter Overflow interrupt:
ECF = 1 enables CF bit in CCON to generate an interrupt. ECF = 0 disables that function of CF.
NOTE:
* User software should not write 1s to reserved bits. These bits may be used in future 8051 family products to invoke new features. In that case, the reset or inactive value of the
new bit will be 0, and its active value will be 1. The value read from a reserved bit is indeterminate.
= oscillator frequency
** –f
OSC
SU00686A
Figure 5. CMOD: PCA Counter Mode Register
CCON Address = OD8H
Reset Value = 00X0 0000B
Bit Addressable
CF CR – CCF4 CCF3 CCF2 CCF1 CCF0
Bit:
76543210
Symbol Function
CF PCA Counter Overflow flag. Set by hardware when the counter rolls over. CF flags an interrupt if bit ECF in CMOD is
set. CF may be set by either hardware or software but can only be cleared by software.
CR PCA Counter Run control bit. Set by software to turn the PCA counter on. Must be cleared by software to turn the PCA
counter off.
– Not implemented, reserved for future use*.
CCF4 PCA Module 4 interrupt flag. Set by hardware when a match or capture occurs. Must be cleared by software.
CCF3 PCA Module 3 interrupt flag. Set by hardware when a match or capture occurs. Must be cleared by software.
CCF2 PCA Module 2 interrupt flag. Set by hardware when a match or capture occurs. Must be cleared by software.
CCF1 PCA Module 1 interrupt flag. Set by hardware when a match or capture occurs. Must be cleared by software.
CCF0 PCA Module 0 interrupt flag. Set by hardware when a match or capture occurs. Must be cleared by software.
NOTE:
* User software should not write 1s to reserved bits. These bits may be used in future 8051 family products to invoke new features. In that case, the reset or inactive value of the
new bit will be 0, and its active value will be 1. The value read from a reserved bit is indeterminate.
SU00036
Figure 6. CCON: PCA Counter Control Register
1998 Jun 04
13
Page 14

Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
CCAPMn Address CCAPM0 0DAH
Not Bit Addressable
Bit:
Symbol Function
– Not implemented, reserved for future use*.
ECOMn Enable Comparator. ECOMn = 1 enables the comparator function.
CAPPn Capture Positive, CAPPn = 1 enables positive edge capture.
CAPNn Capture Negative, CAPNn = 1 enables negative edge capture.
MATn Match. When MATn = 1, a match of the PCA counter with this module’s compare/capture register causes the CCFn bit
TOGn Toggle. When TOGn = 1, a match of the PCA counter with this module’s compare/capture register causes the CEXn
PWMn Pulse Width Modulation Mode. PWMn = 1 enables the CEXn pin to be used as a pulse width modulated output.
ECCFn Enable CCF interrupt. Enables compare/capture flag CCFn in the CCON register to generate an interrupt.
NOTE:
*User software should not write 1s to reserved bits. These bits may be used in future 8051 family products to invoke new features. In that case, the reset or inactive value of the new
bit will be 0, and its active value will be 1. The value read from a reserved bit is indeterminate.
in CCON to be set, flagging an interrupt.
pin to toggle.
CCAPM1 0DBH
CCAPM2 0DCH
CCAPM3 0DDH
CCAPM4 0DEH
– ECOMn CAPPn CAPNn MATn TOGn PWMn ECCFn
76543210
Figure 7. CCAPMn: PCA Modules Compare/Capture Registers
Reset Value = X000 0000B
SU00037
ECOMn CAPPn CAPNn MATn TOGn PWMn ECCFn MODULE FUNCTION
–
X 0 0 0 0 0 0 0 No operation
X X 1 0 0 0 0 X 16-bit capture by a positive-edge trigger on CEXn
X X 0 1 0 0 0 X 16-bit capture by a negative trigger on CEXn
X X 1 1 0 0 0 X 16-bit capture by a transition on CEXn
X 1 0 0 1 0 0 X 16-bit Software Timer
X 1 0 0 1 1 0 X 16-bit High Speed Output
X 1 0 0 0 0 1 0 8-bit PWM
X 1 0 0 1 X 0 X Watchdog Timer
Figure 8. PCA Module Modes (CCAPMn Register)
1998 Jun 04
14
Page 15
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
CEXn
WRITE TO
CCAPnL
WRITE TO
CCAPnH
01
CF CR CCF4 CCF3 CCF2 CCF1 CCF0––
(TO CCFn)
CAPTURE
–– ECOMn CAPPn CAPNn MATn TOGn PWMn ECCFn
0 000
Figure 9. PCA Capture Mode
CF CR CCF4 CCF3 CCF2 CCF1 CCF0––
RESET
CCAPnL
(TO CCFn)
MATCH
ENABLE
CCAPnH
16–BIT COMPARATOR
CCON
(D8H)
PCA TIMER/COUNTER
CH CL
CCAPnH CCAPnL
CCAPMn, n= 0 to 4
(DAH – DEH)
PCA INTERRUPT
SU00749
CCON
(D8H)
PCA INTERRUPT
CH CL
PCA TIMER/COUNTER
–– ECOMn CAPPn CAPNn MATn TOGn PWMn ECCFn
0000
Figure 10. PCA Compare Mode
CCAPMn, n= 0 to 4
(DAH – DEH)
SU00750
1998 Jun 04
15
Page 16
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
WRITE TO
CCAPnL
WRITE TO
CCAPnH
01
RESET
ENABLE
CF CR CCF4 CCF3 CCF2 CCF1 CCF0––
CCAPnH CCAPnL
16–BIT COMPARATOR
CH CL
PCA TIMER/COUNTER
–– ECOMn CAPPn CAPNn MATn TOGn PWMn ECCFn
MATCH
(TO CCFn)
1000
Figure 11. PCA High Speed Output Mode
CCAPnH
CCON
(D8H)
PCA INTERRUPT
TOGGLE
CCAPMn, n: 0..4
(DAH – DEH)
CEXn
SU00751
CCAPnL
0
ENABLE
OVERFLOW
–– ECOMn CAPPn CAPNn MATn TOGn PWMn ECCFn
8–BIT
COMPARATOR
CL
PCA TIMER/COUNTER
0
CL < CCAPnL
CL >= CCAPnL
1
0000
Figure 12. PCA PWM Mode
CCAPMn, n: 0..4
(DAH – DEH)
SU00752
CEXn
1998 Jun 04
16
Page 17
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
WATCHDOG TIMER
The watchdog timer is not directly loadable by the user. Instead, the
value to be loaded into the main timer is held in an autoload register
or is part of the mask ROM programming. In order to cause the main
timer to be loaded with the appropriate value, a special sequence of
software action must take place. This operation is referred to as
feeding the watchdog timer.
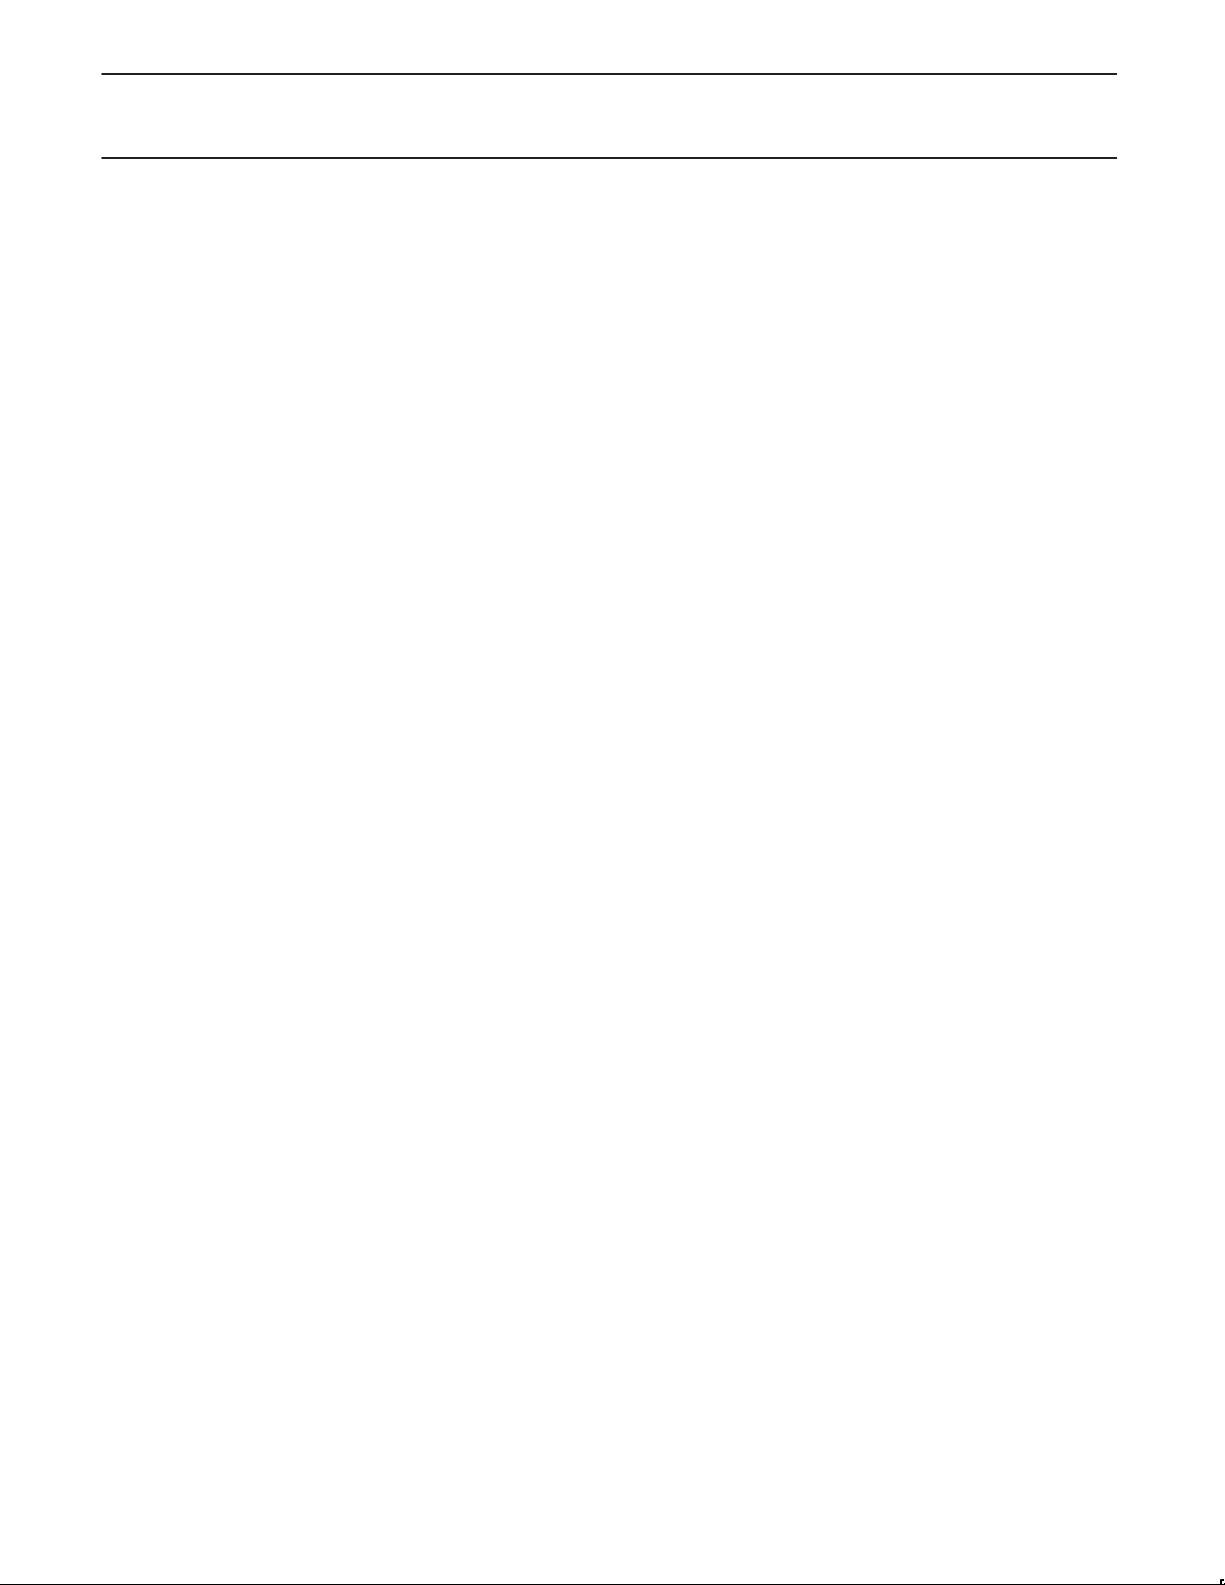
To feed the watchdog, two instructions must be sequentially
executed successfully. No intervening instruction fetches are
allowed, so interrupts should be disabled before feeding the
watchdog. The instructions should move A5H to the WFEED1
register and then 5AH to the WFEED2 register. If WFEED1 is
correctly loaded and WFEED2 is not correctly loaded, then an
immediate underflow will occur.
The watchdog timer subsystem has two modes of operation. Its
principal function is a watchdog timer. In this mode it protects the
system from incorrect code execution by causing a system reset
when the watchdog timer underflows as a result of a failure of
software to feed the timer prior to the timer reaching its terminal
count. If the user does not employ the watchdog function, the
watchdog subsystem can be used as a timer. In this mode, reaching
the terminal count sets a flag. In most other respects, the timer
mode possesses the characteristics of the watchdog mode. This is
done to protect the integrity of the watchdog function.
The watchdog timer subsystem consists of a prescaler and a main
counter. The prescaler has 8 selectable taps of f the final stages and
the output of a selected tap provides the clock to the main counter.
The main counter is the section that is loaded as a result of the
software feeding the watchdog and it is the section that causes the
system reset (watchdog mode) or time-out flag to be set (timer
mode) if allowed to reach its terminal count.
Programming the Watchdog Timer
Both the EPROM and ROM devices have a set of SFRs for holding
the watchdog autoload values and the control bits. The watchdog
time-out flag is present in the PCON register and operates the same
in all versions. In the EPROM device, the watchdog parameters
(autoload value and control) are always taken from the SFRs. In the
ROM device, the watchdog parameters can be mask programmed
or taken from the SFRs. The selection to take the watchdog
parameters from the SFRs or from the mask programmed values is
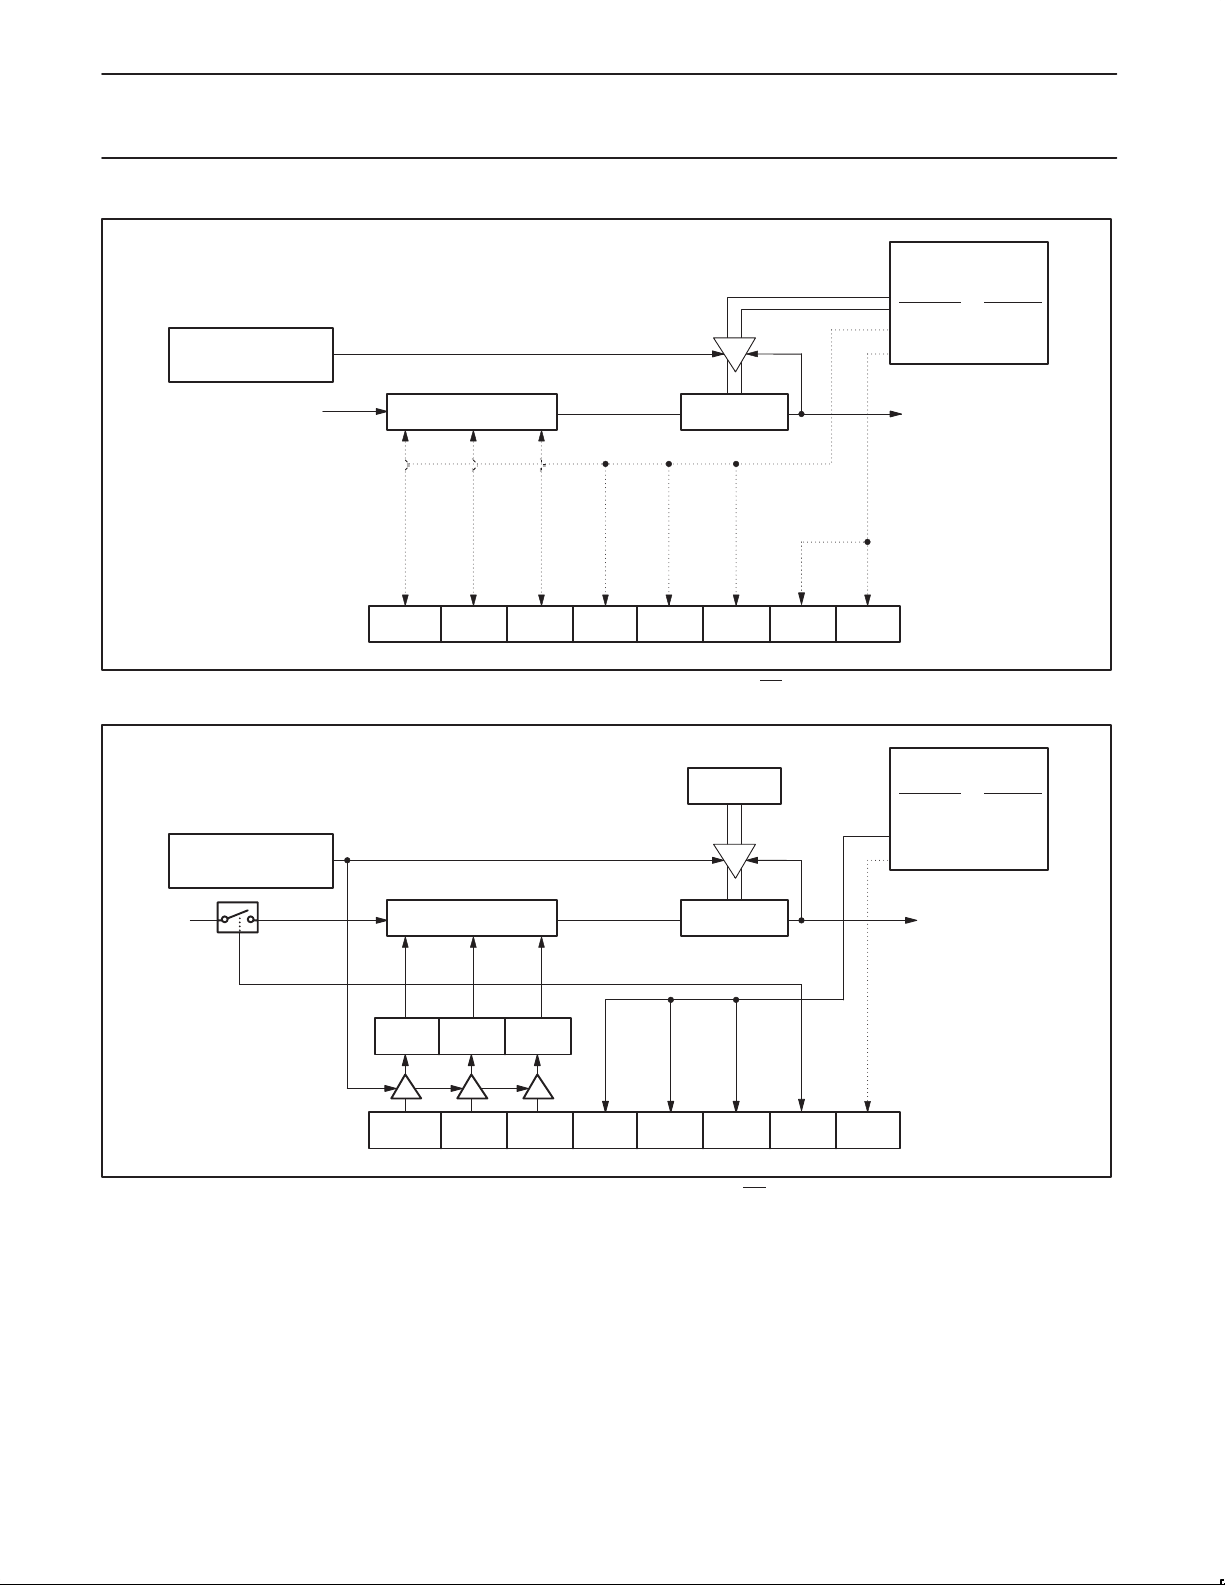
controlled by EA (external access). When EA is high (internal ROM
access), the watchdog parameters are taken from the mask
programmed values. If the watchdog is mask programmed to the
timer mode, then the autoload values and the pre-scaler taps are
taken from the SFRs. When EA is low (external access), the
watchdog parameters are taken from the SFRs. The user should be
able to leave code in his program which initializes the watchdog
SFRs even though he has migrated to the mask ROM part. This
allows no code changes from EPROM prototyping to ROM coded
production parts. The run control bit only functions in timer mode
and does not require a feed sequence to modify.
Watchdog Detailed Operation
EPROM Device (and ROMless Operation: EA = 0)
In the ROMless operation (ROM part, EA = 0) and in the EPROM
device, the watchdog operates in the following manner (see
Figure 15).
Whether the watchdog is in the watchdog or timer mode, when
external RESET is applied, the following takes place:
•Watchdog mode bit set to watchdog mode.
•Watchdog is running.
•Autoload register set to 00 (min. count).
•Watchdog time-out flag is unchanged.
•Prescaler is cleared.
•Prescaler tap set to the highest divide.
•Autoload takes place.
The watchdog can be fed even though it is in the timer mode.
Note that the operational concept is for the watchdog mode of
operation, when coming out of a hardware reset, the software
should load the autoload registers, set the mode to watchdog, clear
the watchdog timeout flag, and then feed the watchdog (cause an
autoload). The watchdog will now be starting at a known point.
If the watchdog is in the watchdog mode and running and happens
to underflow at the time the external RESET is applied, the
watchdog time-out flag will be set.
When the watchdog is in the watchdog mode and the watchdog
underflows, the following action takes place (see Figure 17):
•Autoload takes place.
•Watchdog time-out flag is set
•Mode bit unchanged.
•Watchdog run bit unchanged.
•Autoload register unchanged.
•Prescaler tap unchanged.
•All other device action same as external reset.
Note that if the watchdog underflows, the program counter will start
from 00H as in the case of an external reset. The watchdog time-out
flag can be examined to determine if the watchdog has caused the
reset condition. The watchdog time-out flag bit must be cleared by
software.
When the watchdog is in the timer mode and the timer software
underflows, the following action takes place:
•Autoload takes place.
•Watchdog time-out flag is set
•Mode bit unchanged.
•Watchdog run bit unchanged.
•Autoload register unchanged.
•Prescaler tap unchanged.
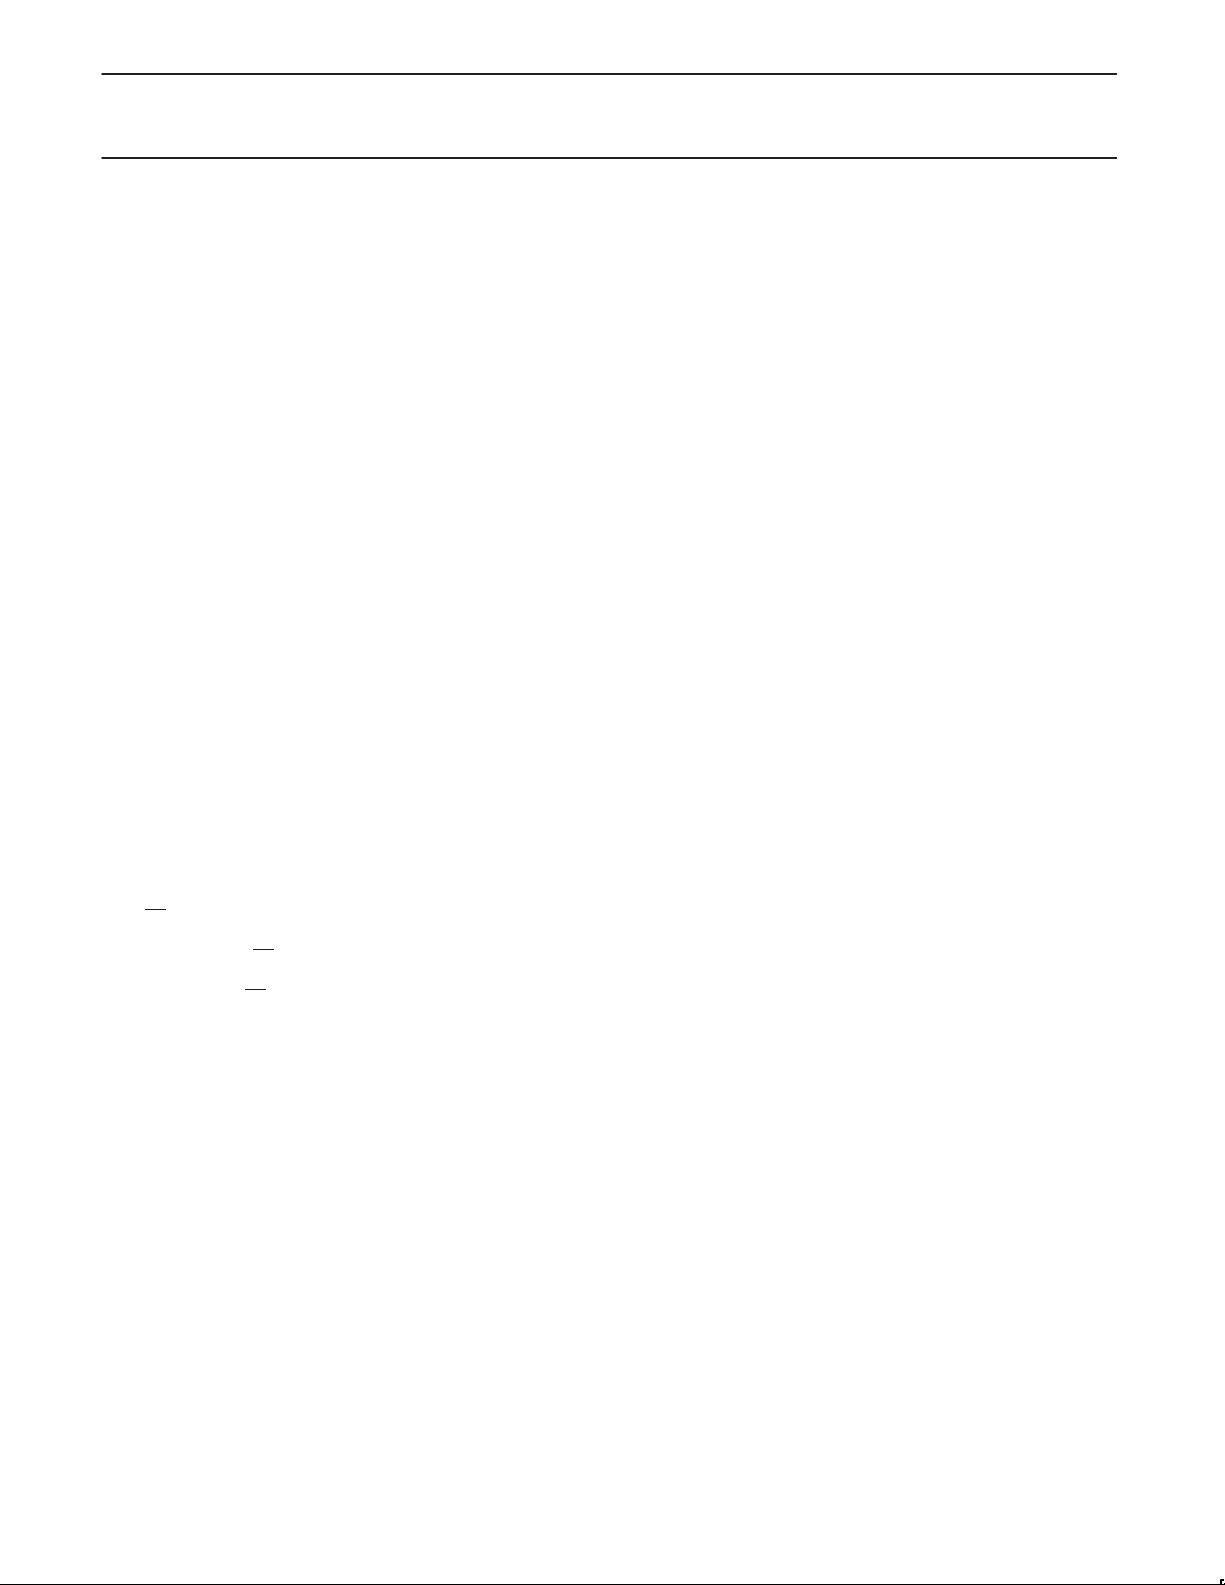
Mask ROM Device (EA = 1)
In the mask ROM device, the watchdog mode bit (WDMOD) is mask
programmed and the bit in the watchdog command register is read
only and reflects the mask programmed selection. If the mask
programmed mode bit selects the timer mode, then the watchdog
run bit (WDRUN) operates as described under EPROM Device. If the
mask programmed bit selects the watchdog mode, then the watchdog
run bit has no effect on the timer operation (see Figure 16).
Watchdog Function
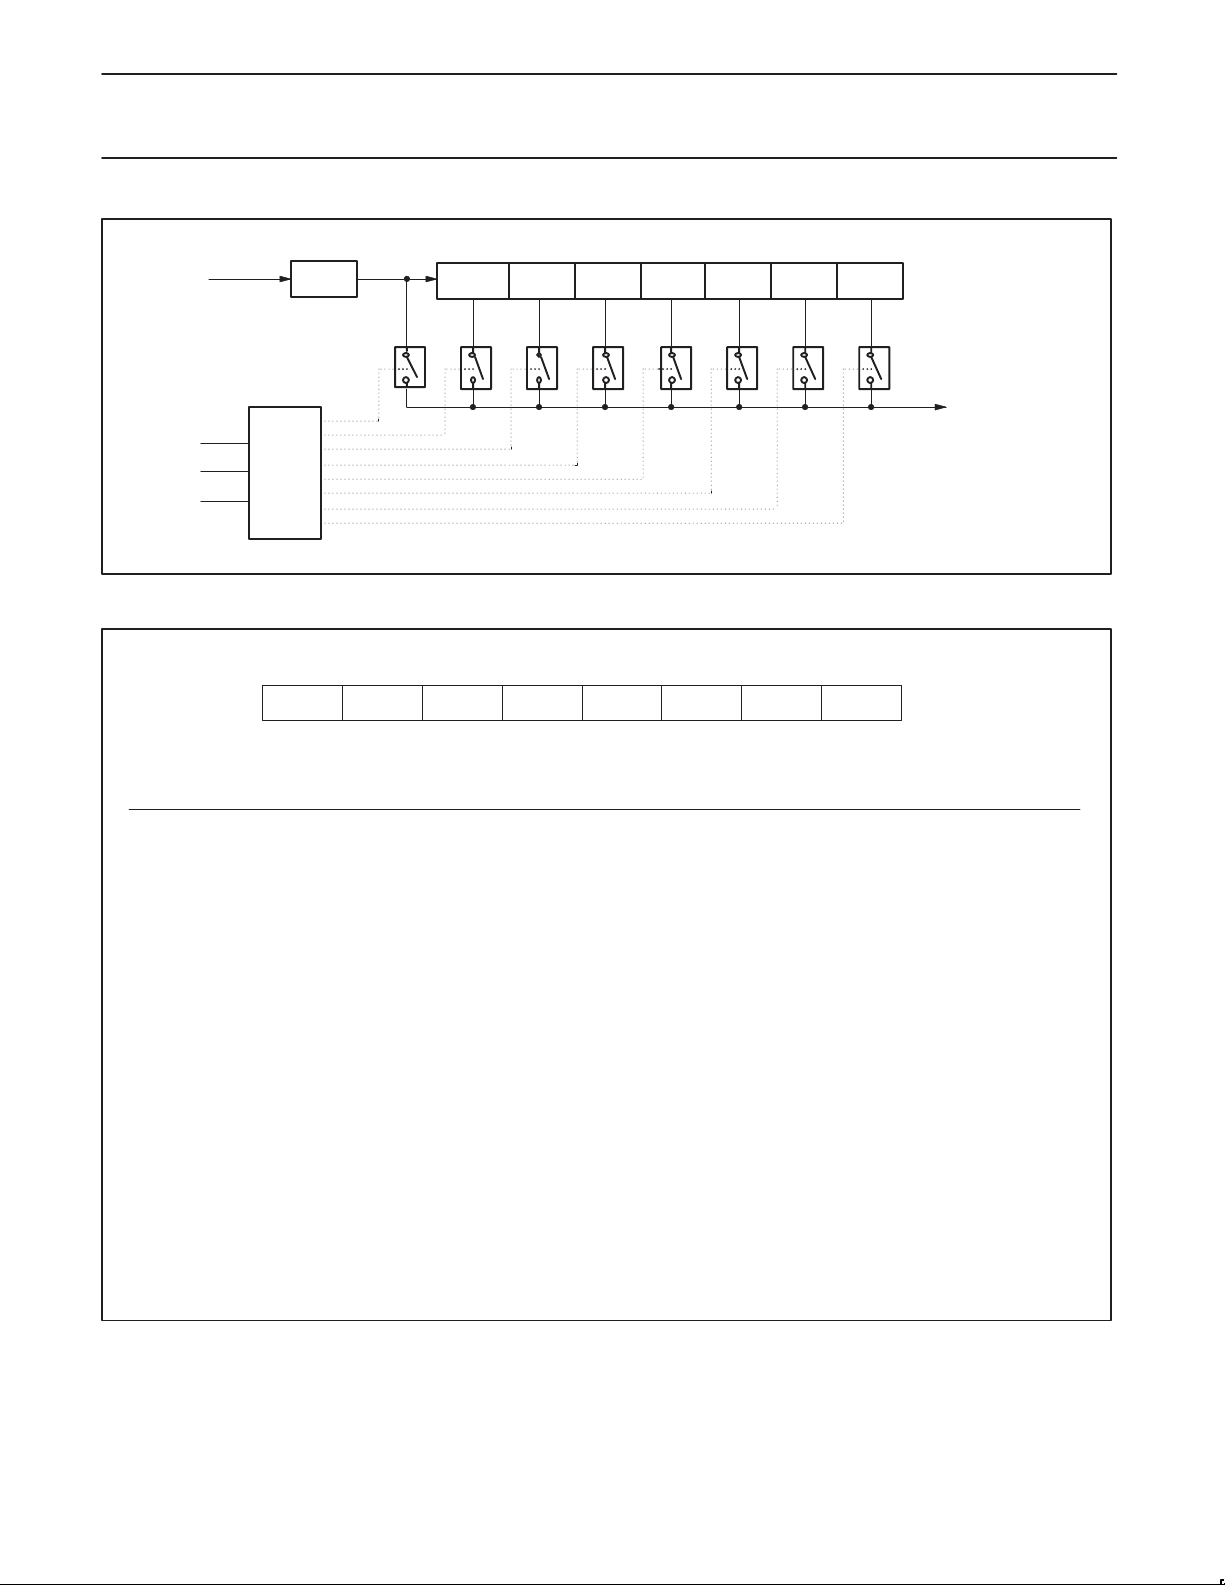
The watchdog consists of a programmable prescaler and the main
timer. The prescaler derives its clock from the on-chip oscillator. The
prescaler consists of a divide by 2 followed by a 13 stage upcounter
with taps from stage 6 through stage 13. This is shown in Figure 18.
1998 Jun 04
17
Page 18
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
The tap selection is programmable. The watchdog main counter is a
down counter clocked (decremented) each time the programmable
prescaler overflows. The watchdog generates an underflow signal
(and is autoloaded) when the watchdog is at count 0 and the prescaler
clock decrements the watchdog. The watchdog is 8 bits long and the
autoload value can range from 0 to FFH. (The autoload value of 0 is
permissible since the prescaler is cleared upon autoload).
This leads to the following user design equations. Definitions :t
OSC
is the oscillator period, N is the selected prescaler tap value, W is
the main counter autoload value, t
time-out value (when the autoload value is 0), t
time-out value (when the autoload value is FFH), t
is the minimum watchdog
MIN
is the maximum
MAX
is the design
D
time-out value.
t
= t
= t
MIN
OSC
MIN
× 2 × 64
× 128 × 256
PRESCALER
× 2
× (W + 1)
MIN
t
MAX
tD = t
(where prescaler = 0, 1, 2, 3, 4, 5, 6, or 7)
Note that the design procedure is anticipated to be as follows. A
t
will be chosen either from equipment or operation
MAX
considerations and will most likely be the next convenient value
higher than t
. (If the watchdog were inadvertently to start from 00H,
D
an underflow would be guaranteed, barring other anomalies, to
occur within t
MAX
).
The software must be written so that a feed operation takes place
seconds from the last feed operation. Some tradeoffs may
every t
D
need to be made. It is not advisable to include feed operations in
minor loops or in subroutines unless the feed operation is a specific
subroutine.
Watchdog Control Register (WDCON)
Address C4H
The following bits of this register are read only in the ROM part
when EA
is high: WDMOD, DPD, OFRE, LVRE, PRE0, PRE1, and
PRE2. That is, the register will reflect the mask programmed values.
In the ROM part with EA
high, these bits are taken from mask coded
bits and are not readable by the program. WDRUN is read only in
the ROM part when EA
is high and WDMOD is in the watchdog
mode. When WDMOD is in the timer mode, WDRUN functions
normally .
The parameters written into WDMOD, DPD, OFRE, LVRE, PRE0,
PRE1, and PRE2 by the program are not applied directly to the
watchdog timer subsystem. The watchdog timer subsystem is
directly controlled by a second register which stores these bits. The
transfer of these bits from the user register to the second control
register takes place when the watchdog is fed. This prevents
random code execution from directly foiling the watchdog function.
This does not affect the operation where these bits are taken from
mask coded values.
The reset values of the WDCON and WDL registers will be such that
the timer resets to the watchdog mode with a timeout period of 2 ×
64 × 128 × t
. The watchdog timer does not generate an interrupt.
OSC
Additional bits in WDCON are used to disable reset generation by
the oscillator fail and low voltage detect circuits. WDCON can be
written by software only by executing a valid watchdog feed
sequence.
WDCON Register Bit Definitions
WDCON.7 PRE2 Prescaler Select 2, reset to 1
WDCON.6 PRE1 Prescaler Select 1, reset to 1
WDCON.5 PRE0 Prescaler Select 0, reset to 1
WDCON.4 LVRE Low Voltage Reset Enable, reset to 1
(enabled)
WDCON.3 OFRE Oscillator Fail Reset Enable, reset to 1
(enabled)
WDCON.2 DPD Disable Power Down
WDCON.1 WDRUN Watchdog Run, reset to 1 (enabled)
WDCON.0 WDMOD Watchdog Mode, reset to 1 (watchdog
mode)
Enhanced UART
The UART operates in all of the usual modes that are described in
the first section of this book for the 80C51. In addition the UART can
perform framing error detect by looking for missing stop bits, and
automatic address recognition. The 8XC576 UART also fully
supports multiprocessor communication as does the standard
80C51 UART.
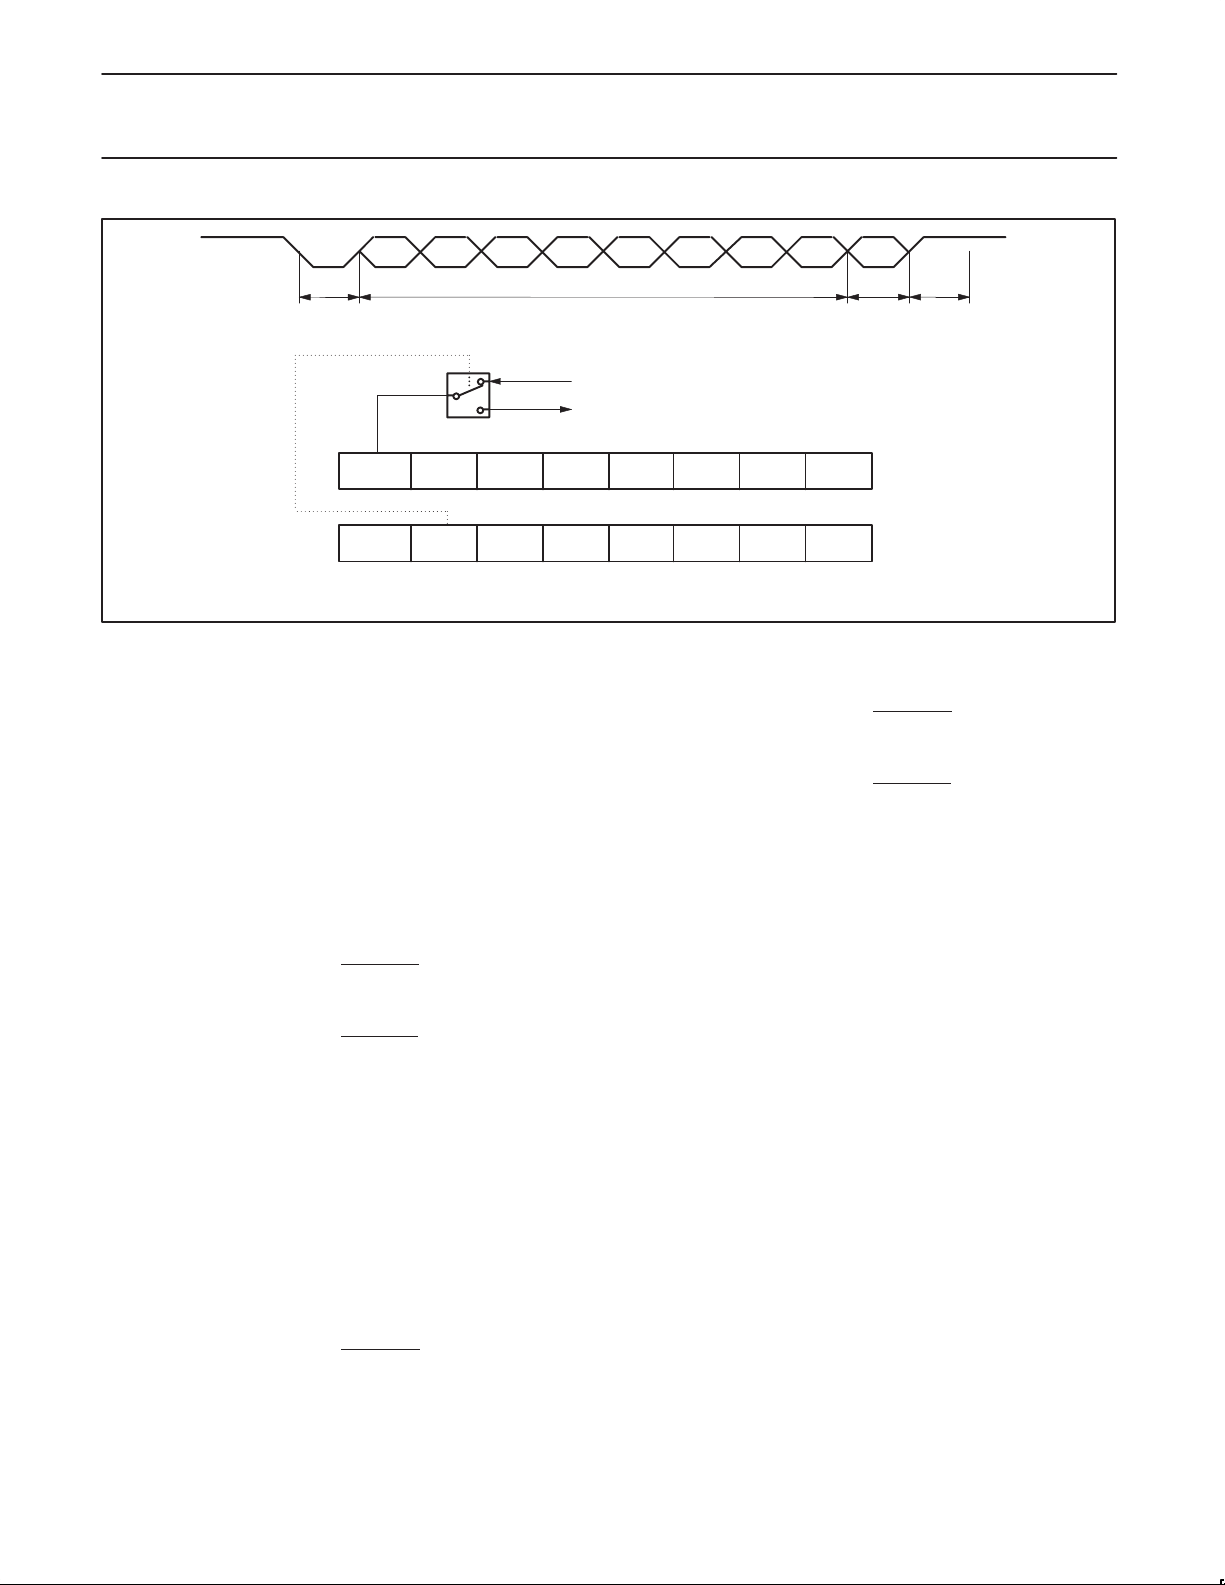
When used for framing error detect the UART looks for missing stop
bits in the communication. A missing bit will set the FE bit in the
SCON register. The FE bit shares the SCON.7 bit with SM0 and the
function of SCON.7 is determined by PCON.6 (SMOD0) (see Figure
20). If SMOD0 is set then SCON.7 functions as FE. SCON.7
functions as SM0 when SMOD0 is cleared. When used as FE
SCON.7 can only be cleared by software. Refer to Figure 19.
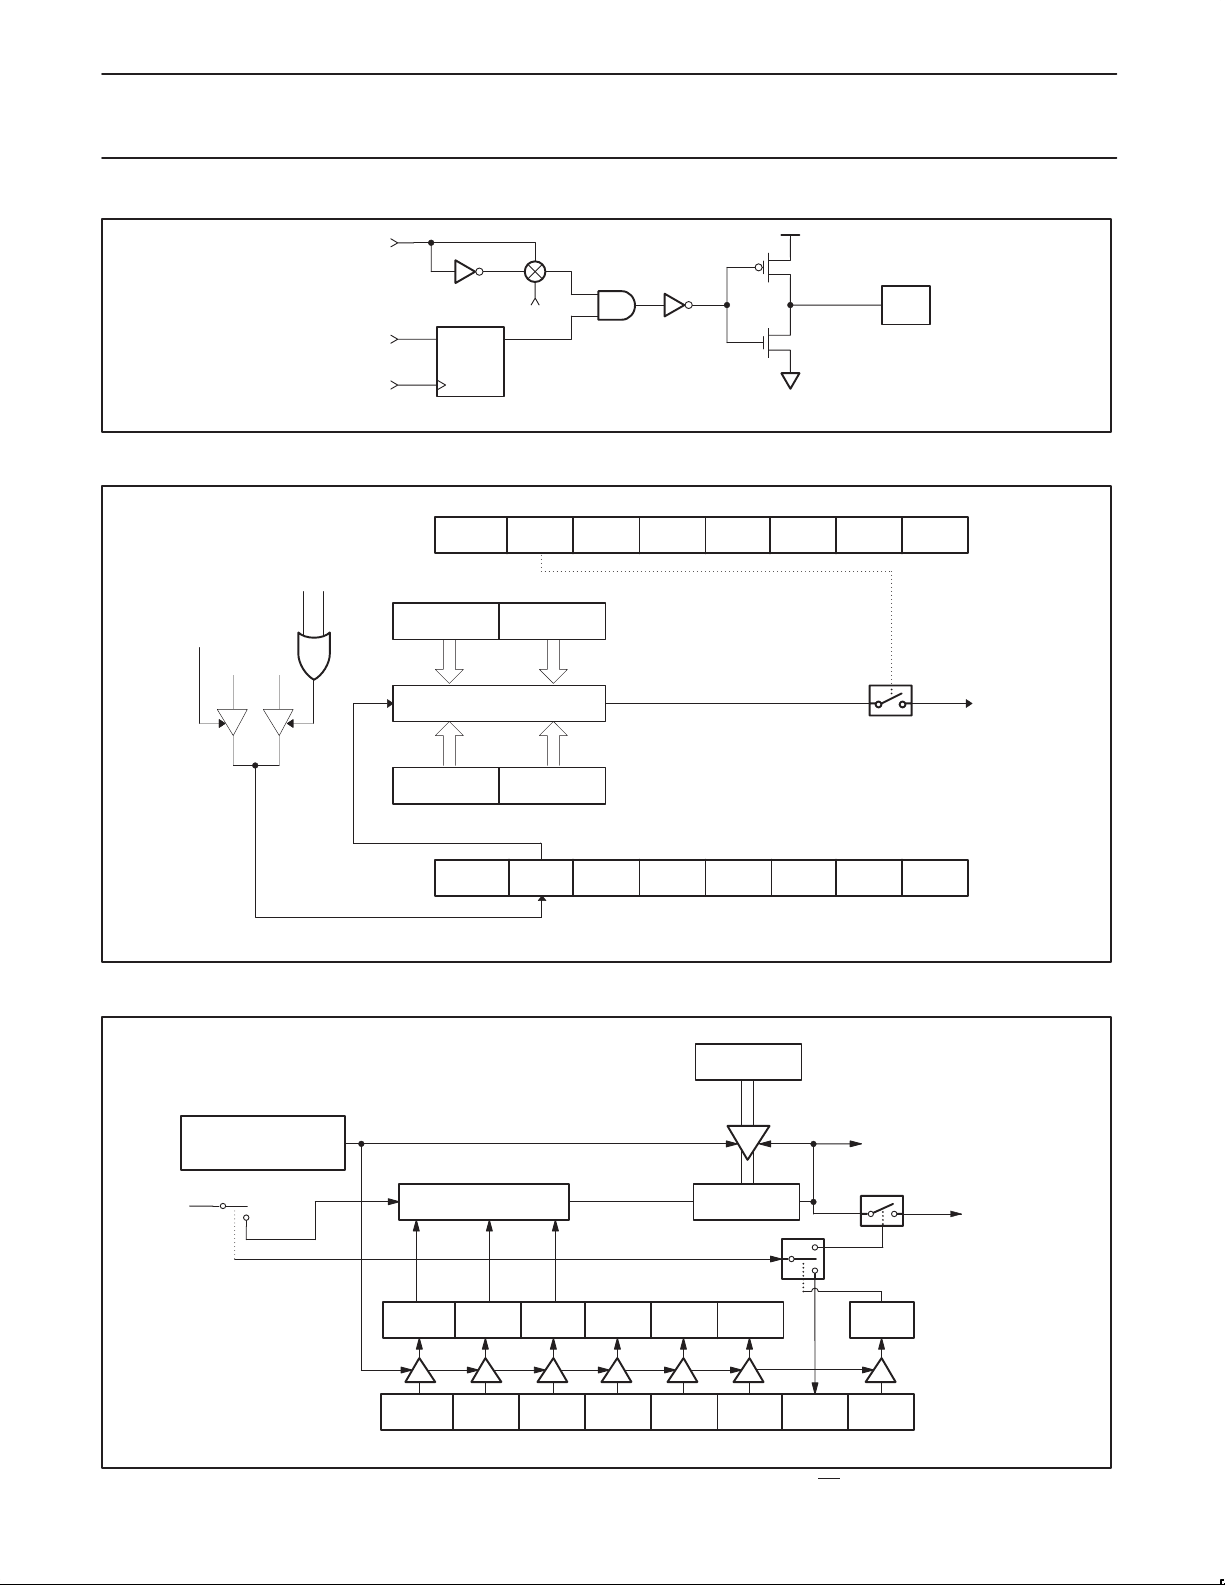
The serial port transmitter data can be inverted by setting the TXI
(AUXR.2) bit. For normal operation, the TXI bit should be cleared.
Automatic Address Recognition
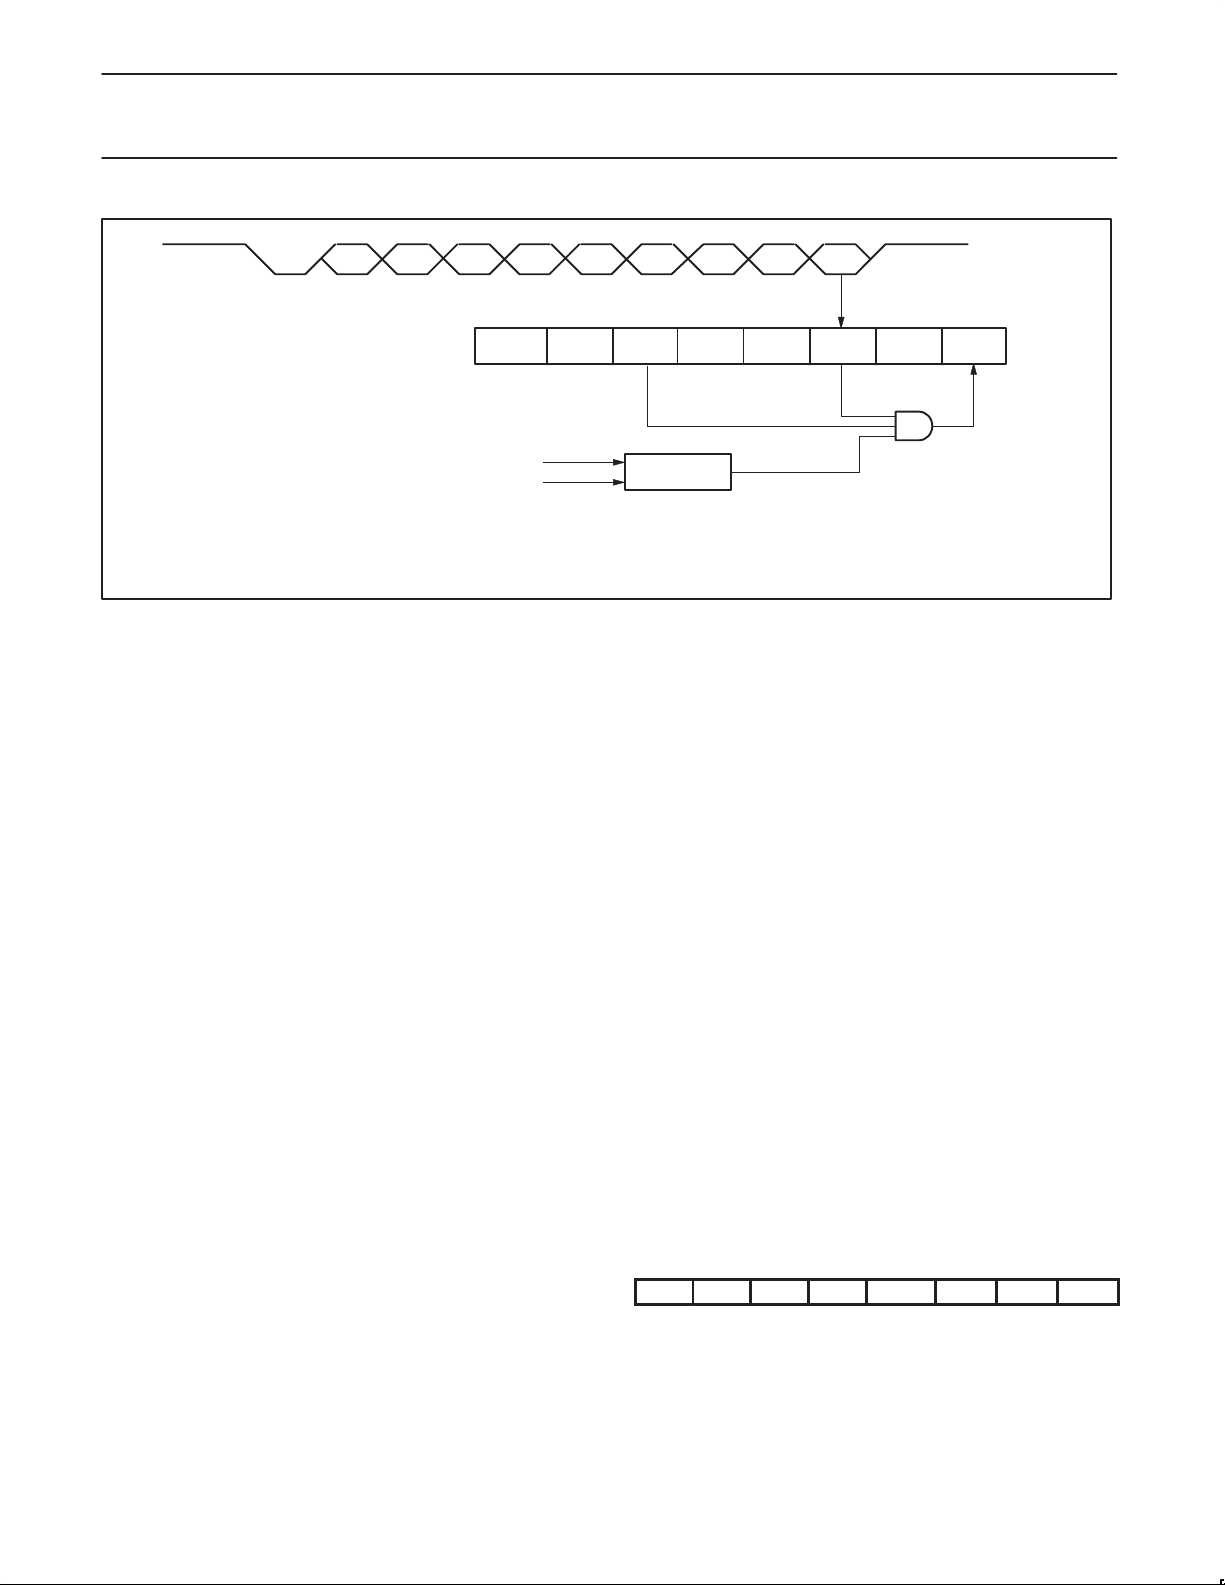
Automatic Address Recognition is a feature which allows the UART
to recognize certain addresses in the serial bit stream by using
hardware to make the comparisons. This feature saves a great deal
of software overhead by eliminating the need for the software to
examine every serial address which passes by the serial port. This
feature is enabled by setting the SM2 bit in SCON. In the 9 bit UART
modes, mode 2 and mode 3, the Receive Interrupt flag (RI) will be
automatically set when the received byte contains either the “Given”
address or the “Broadcast” address. The 9 bit mode requires that
the 9th information bit is a 1 to indicate that the received information
is an address and not data. Automatic address recognition is shown
in Figure 21.
The 8 bit mode is called Mode 1. In this mode the RI flag will be set
if SM2 is enabled and the information received has a valid stop bit
following the 8 address bits and the information is either a Given or
Broadcast address.
Mode 0 is the Shift Register mode and SM2 is ignored.
1998 Jun 04
18
Page 19
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
TXD
TXI
INT. BUS
WRITE TO LATCH
Figure 13. TXI (AUXR.2) Bit Inverts the TxD Pin (P3.1) When Set
DQ
P3.1
LATCH
PROGRAMMABLE OUTPUT BUFFER
83C576/87C576
P3.1
PIN
SU00711
WRITE TO
CCAP4H
WRITE TO
CCAP4L
01
WATCHDOG FEED SEQUENCE
MOV WFEED1,#0A5H
MOV WFEED2,#5AH
RESET
ENABLE
CIDL WDTE –– –– –– CPS1 CPS0 ECF
CCAP4H CCAP4L
16–BIT COMPARATOR
CH CL
PCA TIMER/COUNTER
–– ECOMn CAPPn CAPNn MATn TOGn PWMn ECCFn
MATCH
1
X000
Figure 14. PCA Watchdog Timer
WDL (C1H)
X
WDTOF (PCON.2)
CMOD
(D9H)
RESET
CCAPM4
(DEH)
SU00042
OSC/2
1998 Jun 04
PRESCALER
PRE2 PRE1 PRE0 LVRE OFRE DPD WDRUN WDMOD
8–BIT DOWN
COUNTER
Figure 15. Watchdog Timer in 87C576 and 80C576 / 83C576 (EA = 0)
19
RESET
SHADOW REGISTER
FOR WDCON
WDCON
(C4H)
SU00657C
Page 20
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
ROM–CODE
WATCHDOG FEED SEQUENCE
MOV WFEED1,#0A5H
MOV WFEED2,#5AH
Figure 16. Watchdog Timer of 83C576 in Watchdog Mode (EA = 1, WDMOD = 1)
WATCHDOG FEED SEQUENCE
MOV WFEED1,#0A5H
MOV WFEED2,#5AH
PRESCALEROSC/2
PRE2 PRE1 PRE0 LVRE OFRE DPD WDRUN WDMOD
8–BIT DOWN
COUNTER
WDL (C1H)
1
1
CONTENT
WDL
WDCON
RESET
WDTOF (PCON.2)
WDCON
(C4H)
ROM–CODE
CONTENT
WDCON
ADDRESS
2031H
2030H
SU00658C
ADDRESS
2030H
PRESCALEROSC/2
PRE2 PRE1 PRE0 LVRE OFRE DPD WDRUN WDMOD
8–BIT DOWN
COUNTER
0
Figure 17. Watchdog Timer of 83C576 in Timer Mode (EA = 1, WDMOD = 0)
WDTOF (PCON.2)
WDCON
(C4H)
SU00659C
1998 Jun 04
20
Page 21
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
OSC/2 ÷64
PRE2
PRE1
PRE0
DECODE
÷64 ÷128 ÷256 ÷512 ÷1024 ÷2048 ÷4096 ÷8192
000
001
010
011
100
101
110
111
÷2 ÷2 ÷2 ÷2 ÷2 ÷2 ÷2
TO WATCHDOG
DOWN COUNTER
SU00660
Figure 18. Watchdog Prescaler
SCON Address = 98H
Reset Value = 0000 0000B
Bit Addressable
SM0/FE SM1 SM2 REN TB8 RB8 Tl Rl
Bit: 76543210
(SMOD0/1)*
Symbol Function
FE Framing Error bit. This bit is set by the receiver when an invalid stop bit is detected. The FE bit is not cleared by valid
frames but should be cleared by software. The SMOD0 bit must be set to enable access to the FE bit.
SM0 Serial Port Mode Bit 0, (SMOD0 must = 0 to access bit SM0)
SM1 Serial Port Mode Bit 1
SM0 SM1 Mode Description Baud Rate**
0 0 0 shift register f
OSC
/12
0 1 1 8-bit UART variable
1 0 2 9-bit UART f
OSC
/64 or f
OSC
/32
1 1 3 9-bit UART variable
SM2 Enables the Automatic Address Recognition feature in Modes 2 or 3. If SM2 = 1 then Rl will not be set unless the
received 9th data bit (RB8) is 1, indicating an address, and the received byte is a Given or Broadcast Address.
In Mode 1, if SM2 = 1 then Rl will not be activated unless a valid stop bit was received, and the received byte is a
Given or Broadcast Address. In Mode 0, SM2 should be 0.
REN Enables serial reception. Set by software to enable reception. Clear by software to disable reception.
TB8 The 9th data bit that will be transmitted in Modes 2 and 3. Set or clear by software as desired.
RB8 In modes 2 and 3, the 9th data bit that was received. In Mode 1, if SM2 = 0, RB8 is the stop bit that was received.
In Mode 0, RB8 is not used.
Tl Transmit interrupt flag. Set by hardware at the end of the 8th bit time in Mode 0, or at the beginning of the stop bit in the
other modes, in any serial transmission. Must be cleared by software.
Rl Receive interrupt flag. Set by hardware at the end of the 8th bit time in Mode 0, or halfway through the stop bit time in
the other modes, in any serial reception (except see SM2). Must be cleared by software.
NOTE:
*SMOD0/1 is located at PCON.6, PCON.7
**f
= oscillator frequency
OSC
Figure 19. SCON: Serial Port Control Register
SU00766
1998 Jun 04
21
Page 22
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
D0 D1 D2 D3 D4 D5 D6 D7 D8
83C576/87C576
START
BIT
SM0 / FE SM1 SM2 REN TB8 RB8 TI RI
SMOD1 SMOD0 – POF LVF GF0 GF1 IDL
0 : SCON.7 = SM0
1 : SCON.7 = FE
Figure 20. UART Framing Error Detection
Using the Automatic Address Recognition feature allows a master to
selectively communicate with one or more slaves by invoking the
Given slave address or addresses. All of the slaves may be
contacted by using the Broadcast address. Two special Function
Registers are used to define the slave’s address, SADDR, and the
address mask, SADEN. SADEN is used to define which bits in the
SADDR are to be used and which bits are “don’t care”. The SADEN
mask can be logically ANDed with the SADDR to create the “Given”
address which the master will use for addressing each of the slaves.
Use of the Given address allows multiple slaves to be recognized
while excluding others. The following examples will help to show the
versatility of this scheme:
Slave 0 SADDR = 1100 0000
SADEN = 1111 1101
Given = 1100 00X0
Slave 1 SADDR = 1100 0000
SADEN = 1111 1110
Given = 1100 000X
In the above example SADDR is the same and the SADEN data is
used to differentiate between the two slaves. Slave 0 requires a 0 in
bit 0 and it ignores bit 1. Slave 1 requires a 0 in bit 1 and bit 0 is
ignored. A unique address for Slave 0 would be 1100 0010 since
slave 1 requires a 0 in bit 1. A unique address for slave 1 would be
1100 0001 since a 1 in bit 0 will exclude slave 0. Both slaves can be
selected at the same time by an address which has bit 0 = 0 (for
slave 0) and bit 1 = 0 (for slave 1). Thus, both could be addressed
with 1100 0000.
In a more complex system the following could be used to select
slaves 1 and 2 while excluding slave 0:
Slave 0 SADDR = 1100 0000
SADEN = 1111 1001
Given = 1100 0XX0
DATA BYTE
SET FE BIT IF STOP BIT IS 0 (FRAMING ERROR)
SM0 TO UART MODE CONTROL
Slave 1 SADDR = 1110 0000
SADEN = 1111 1010
Given = 1110 0X0X
Slave 2 SADDR = 1110 0000
SADEN = 1111 1100
Given = 1110 00XX
In the above example the differentiation among the 3 slaves is in the
lower 3 address bits. Slave 0 requires that bit 0 = 0 and it can be
uniquely addressed by 1110 0110. Slave 1 requires that bit 1 = 0 and
it can be uniquely addressed by 1110 and 0101. Slave 2 requires
that bit 2 = 0 and its unique address is 1110 0011. To select Slaves 0
and 1 and exclude Slave 2 use address 1110 0100, since it is
necessary t make bit 2 = 1 to exclude slave 2.
The Broadcast Address for each slave is created by taking the
logical OR of SADDR and SADEN. Zeros in this result are treated
as don’t-cares. In most cases, interpreting the don’t-cares as ones,
the broadcast address will be FF hexadecimal.
Upon reset SADDR (SFR address 0A9H) and SADEN (SFR
address 0B9H) are loaded with 0s. This produces a given address
of all “don’t cares” as well as a Broadcast address of all “don’t
cares”. this effectively disables the Automatic Addressing mode and
allows the microcontroller to use standard 80C51 type UART drivers
which do not make use of this feature.
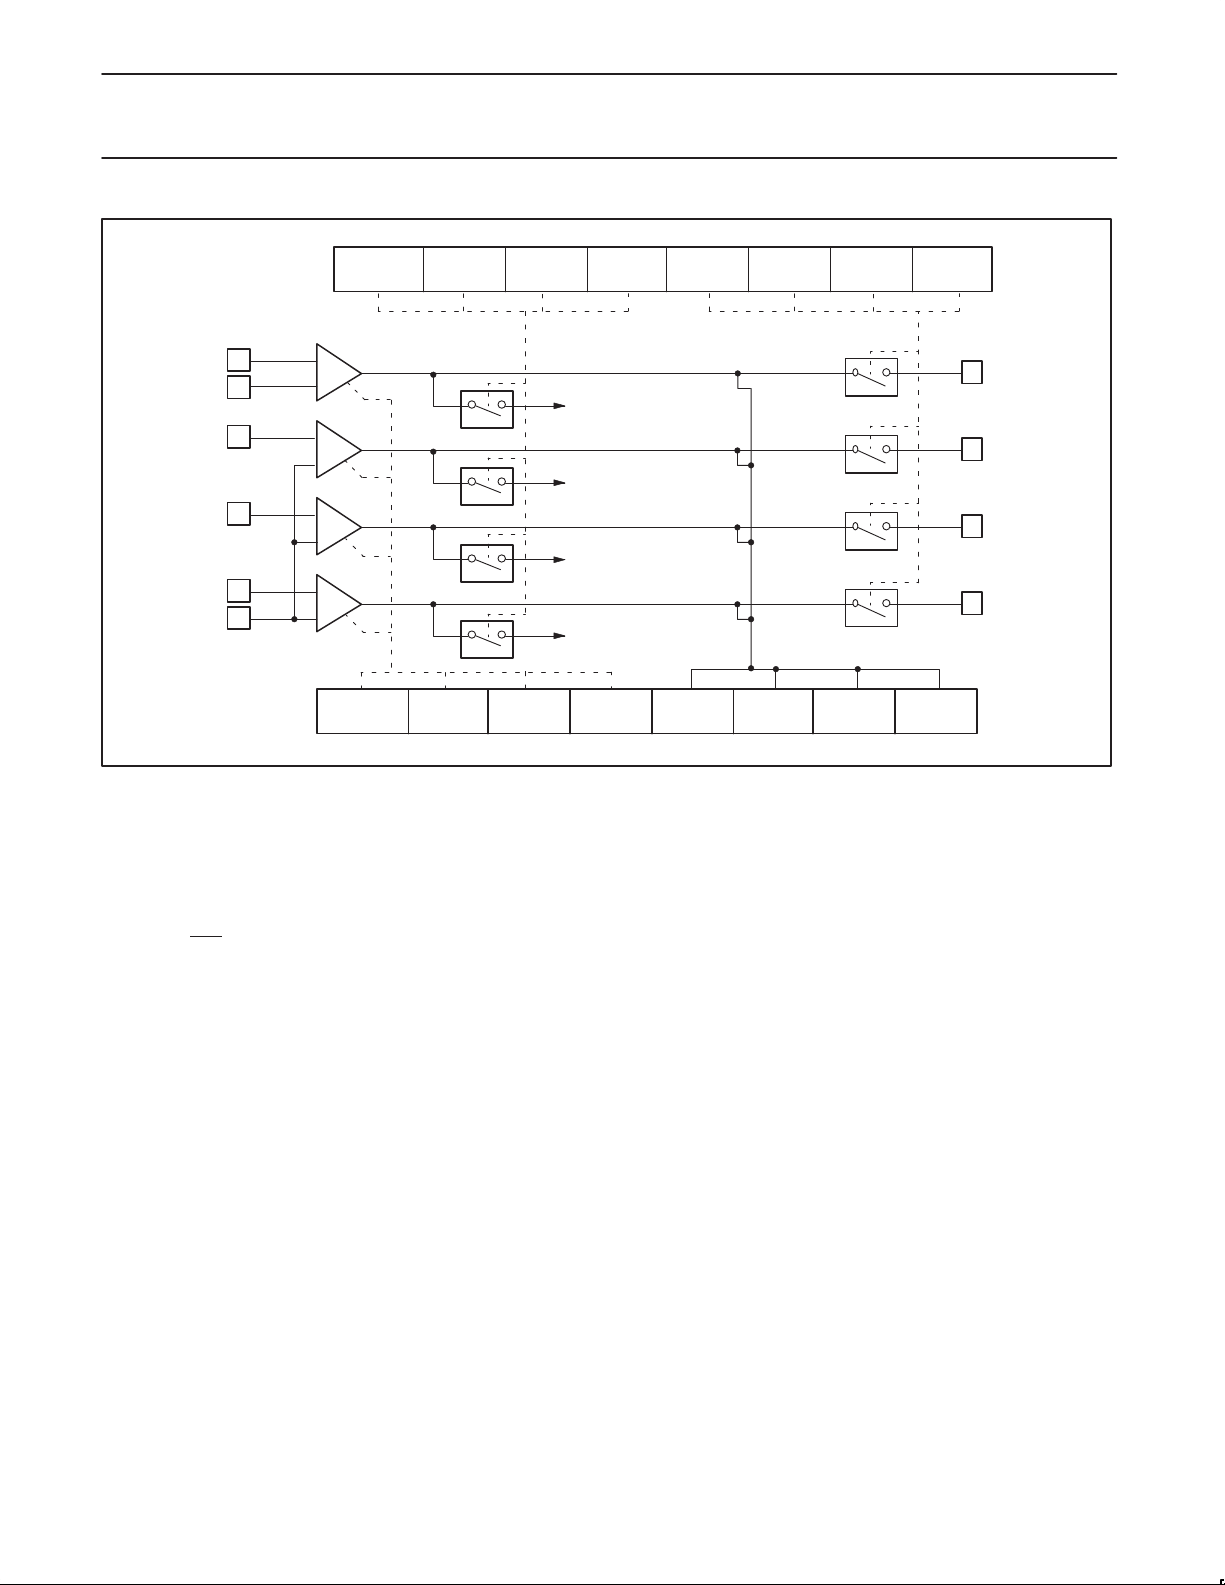
Analog Comparators
Four analog comparators are provided on chip. Three comparators
have a common negative reference CMPR- and independent
positive inputs CMP1+, CMP2+, CMP3+ on port 3. The fourth
comparator has independent positive and negative inputs CMP0+
and CMP0- on port 2. The CMP register contains an output and
enable bit for each comparator. Figure 22 shows the connection of
the comparators.
When the comparator is enabled, the port should be configured by
the user as high impedance.
ONLY IN
MODE 2, 3
SCON
(98H)
PCON
(87H)
STOP
BIT
SU00044
1998 Jun 04
22
Page 23
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
D0 D1 D2 D3 D4 D5 D6 D7 D8
83C576/87C576
SM0 SM1 SM2 REN TB8 RB8 TI RI
1
1
RECEIVED ADDRESS D0 TO D7
PROGRAMMED ADDRESS
IN UART MODE 2 OR MODE 3 AND SM2 = 1:
INTERRUPT IF REN=1, RB8=1 AND “RECEIVED ADDRESS” = “PROGRAMMED ADDRESS”
– WHEN OWN ADDRESS RECEIVED, CLEAR SM2 TO RECEIVE DATA BYTES
– WHEN ALL DATA BYTES HAVE BEEN RECEIVED: SET SM2 TO WAIT FOR NEXT ADDRESS.
Figure 21. UART Multiprocessor Communication, Automatic Address Recognition
CMP Register Bit Definitions
CMP.7 enable comparator 3
CMP.6 enable comparator 2
CMP.5 enable comparator 1,
CMP.4 enable comparator 0
CMP.3 comparator 3 output (read only)
CMP.2 comparator 2 output (read only)
CMP.1 comparator 1 output (read only)
CMP.0 comparator 0 output (read only)
All comparators are disabled automatically in power down mode. In
idle mode unused comparators should be disabled by software to
save power. A comparator can generate an interrupt that will
terminate idle mode when used to drive a PCA capture input.
The CMPE register contains bits to enable each comparator to drive
external output pins or internal PCA capture inputs. When the
comparator is configured for external output, the user must also
configure the output port in one of its output modes. The comparator
output is wire-ORed with the corresponding port SFR bit, so the
SFR bit must also be set by software to enable the output.
CMPE Register Bit Definitions
CMPE.7 enables comparator 3 to drive CEX3
CMPE.6 enables comparator 2 to drive CEX2
CMPE.5 enables comparator 1 to drive CEX1
CMPE.4 enables comparator 0 to drive CEX0
CMPE.3 enables comparator 3 output on P2.3
CMPE.2 enables comparator 2 output on P2.2
CMPE.1 enables comparator 1 output on P2.1
CMPE.0 enables comparator 0 output on P2.0
When 1s are written to CMPE bits 7-4, the comparator outputs will
drive the corresponding capture input. When 1s are written to CMPE
bits 3-0 the comparator output will also drive the corresponding
port 2 pin. If the comparator’s enabled to drive the capture input but
not the port pin, then the port pin can be used for general purpose
I/O. When a comparator output is enabled, the user will need to
configure the port for one of its output modes.
There are two special function registers associated with the
comparators. They are CMP which contains the comparator enables
1
0
11 X
COMPARATOR
and a bit that can be read by software to determine the state of each
comparator’s output, and CMPE which controls whether the output
from each comparator drives the associated output pin or a capture
input associated with one of the PCA modules.
The CMP registers bits 0–3 can be read by software to determine
the state of the output of each comparator. To do this the associated
comparator must be enabled but the output in port 2 can be
disabled. This allows easy polling of the comparator output value
without the need to use up a port pin.
The CMPE register allows the comparator to drive the associated
PCA module capture input, so that on compare a capture can be
generated in the PCA. Bits 0–3 of this register enable the
comparator output to drive the associated port 2 output circuitry.
Used as a comparator output, the output mode for this port must be
configured for output by the user and the port output SFR bit latch
must be set. If the comparator is not enabled to drive the port 2
circuitry, the associated port 2 pin can be used for other I/O. This
includes when a comparator is enabled to drive the capture input to
a PCA module.
Reduced EMI Mode
There are two bits in the AUXR register that can be set to reduce
the internal clock drive and disable the ALE output. AO (AUXR.0)
when set turns off the ALE output. LO (AUXR.1) when set reduces
the drive of the internal clock circuitry. Both bits are cleared on
Reset. With LO set the 8XC576 will still operate at 12MHz, and will
have reduced EMI in the range above 100MHz.
8XC576 Reduced EMI Mode
AUXR (0X8E)
–– –– –– –– RST TXI LO AO
AO: Turns off ALE output.
LO: Reduces drive of internal clock circuitry. 8XC576 spec’d to
12MHz when LO set.
TXI: Inverts TxD when set.
RST: Software reset.
SCON
(98H)
SU00045
1998 Jun 04
23
Page 24
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
EC3TDC EC2TDC EC1TDC EC0TDC EC3OD * EC2OD * EC1OD * EC0OD *
P3.6 / CMP0+
P3.7 / CMP0–
P3.4 / CMP1+
P3.3 / CMP2+
P3.2 / CMP3+
P3.5 / CMPR–
* : WILL DISABLE PULLUPS
ON RELEVANT PINS
+
–
ENABLE
+
–
ENABLE
+
–
ENABLE
+
–
ENABLE
EC3DP * EC2DP * EC1DP * EC0DP * C3RO C2RO C1RO C0RO
Figure 22. Analog Comparators
INTERNAL RESET
Internal resets (see Figure 1) generated by the power on, low
voltage, software (SRST), watchdog and oscillator fail detect circuits
are self timed to guarantee proper initialization of the 8XC576. Reset
will be held approximately 24 oscillator periods after normal
conditions are detected by all enabled detect circuits. Internal resets
do not drive RST
but will cause missing pulses on ALE.
Analog to Digital Converter
The 8XC576 has a 6 channel10 bit successive approximation A/D
converter with separate result registers for each channel. Operating
modes are provided for single or multiple channel conversions and
multiple conversions of a single channel without software
intervention. The ADC can also be operated in 8 bit mode with faster
conversion times. Registers ADC0H–ADC5H contain the MSBs and
ADC0L–ADC5L bits 6 and 7 contain the 2 LSBs of the conversion
result for each channel. The ADCS register determines which
channels are converted in multiple channel modes. If the ADCS bit
corresponding to a channel is set, that channel is converted, else if
the bit is clear the channel is skipped.
A/D Channel Select (ADCS) Register (Reset Value = 00H)
ADCS5 ADCS.5 – A/D channel 5 select bit
ADCS4 ADCS.4 – A/D channel 4 select bit
ADCS3 ADCS.3 – A/D channel 3 select bit
ADCS2 ADCS.2 – A/D channel 2 select bit
ADCS1 ADCS.1 – A/D channel 1 select bit
ADCS0 ADCS.0 – A/D channel 0 select bit
A/D Control (ADCON) Register (Reset Value = 00H)
ADF ADCON.7 – A/D conversion complete flag
ADCE ADCON.6 – A/D conversion enable
AD8M ADCON.5 – A/D 8-bit mode
CMPE
P2.0 / CMP0
TO CEX0 INPUT OF
PCA MODULE 0
P2.1 / CMP1
TO CEX1 INPUT OF
PCA MODULE 1
P2.2 / CMP2
TO CEX2 INPUT OF
PCA MODULE 2
P2.3 / CMP3
TO CEX3 INPUT OF
PCA MODULE 3
CMP
(C0H)
SU00517C
AMOD1 ADCON.4 –A/D mode select bit 1
AMOD0 ADCON.3 –A/D mode select bit 0
ASCA2 ADCON.2 – A/D channel address bit 2
ASCA1 ADCON.1 – A/D channel address bit 1
ASCA0 ADCON.0 – A/D channel address bit 0
AMOD1 AMOD0
0 0 Single Conversion Mode – channel selected by bits
ASCA2..0 in ADCON is converted, the result placed
in the associated result registers; ADF is set on
completion.
0 1 Mulitple Channel Scan Mode – all channels selected
in the ADCS register are converted starting with the
channel addressed by bits ASCA2..0 in ADON,
conversion results are placed in the corres ponding
result r egisters for each channel. ADF is set when
the last conversion is completed.
1 0 Single Channel Multiple Conversion – channel
selected by bits ASCA2..0 in ADCON is converted 6
times and all 6 results are saved in ADC0H–ADC5H
and ADC0L–ADC5L, ADF is set when all
conversions are complete.
1 1 Multiple Channel Continuous – same as Multiple
Channel Scan mode but repeats as long as
ADCE=1, ADF is set when all channels have been
converted once. Hardware will prevent the ADC
from wiriting to the result registers while they are
being read.
Flag ADF is set upon completion of a conversion, if the ADC
interrupt enable bit EAD is set, the program will vector to the ADC
interrupt location when ADF is set.
(92H)
1998 Jun 04
24
Page 25
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
PWMs
The pulse width modulator system of the 8XC576 contains two
PWM output channels. These channels generate pulses of
programmable length and interval. The prescaler and counter are
common to both PWM channels.
The prescaler is loaded with the complement of the PWMP register
during counter overflow, internal reset, and when EN/CLR# = 0. The
repetition frequency is defined by the 8-bit prescaler which clocks
the counter. The prescaler division factor = PWMP+1. Reading the
PWMP gives the current reload value. The actual count of the
prescaler cannot be read.
The 8-bit counter counts from 0–254 inclusive. The value of the
counter is compared to the contents of the compare registers PWM0
and PWM1. When the counter compares to the compare register,
that register’s output goes LOW. When the counter reaches zero the
output is set HIGH unless PWMn = 00H. The duty cycle of each
channel is defined by the contents of its compare register and is in
the range of 0 to 1, programmed in increments of 1/255.
The outputs can be set continuously low by loading PWMn with 00H
and continuously high by loading with FFH.
The PWM counter is enabled with bit EN/CLR# of the PWCON
register. Output to the port pin is separately enabled by setting the
PWEn bits in the PWCON register. The counter remains active if
EN/CLR# is set even if both PWEn bits are reset. The PWM function
is reset by a chip reset. In idle mode, the PWM will function as
configured by PWCON. In power-down the state of the PWM will
freeze when the internal clock stops. If the chip is awakened with an
external interrupt, the PWM will continue to function from its state
when power-down was entered. The EN/CLR# bit of PWCON will
clear the counter and load the contents of the PWMP into the
prescaler when set LOW. If PWEn is set at this time the output will
go HIGH unless PWMn is 00H.
The repetition frequency is given by:
f
f
PWM
(510 (1 PWMP))
An oscillator frequency of 12MHz results in a repetition range of
92Hz to 23.5KHz.
The high/low ratio of PWMn is PWMn/(255–PWMn) for PWMn
values except 255. A PWMn value of 255 results in a high PWMn
output.
In order for the PWMn output to be used as a standard I/O pin,
PWMn must be reset. The PWM counter can still be used as an
internal timer by setting EN/CLR#.
OSC
Pulse Width Modulator Control Register Bit Definitions
(PWCON = BCH)
PWMF PWCON.3 Counter overflow flag,
EN/CLR
PWE1 PWCON.1 PWM1 output to P2.7 pin enable
PWE0 PWCON.0 PWM0 output to P2.6 pin enable
Auxiliary Register Bit Definitions (AUXR =8EH)
RST AUXR.3 Software reset bit
TXI AUXR.2 SIO TxD invert
LO AUXR.1 Low Speed, reduces internal clock drive
AO AUXR.0 ALE Off, when set turns off ALE
Interrupt Enable 0 (IE0) Register
EA IE0.7 Enable all interrupts
EC IE0.6 Enable PCA interrupt
ET2 IE0.5 Enable Timer 2 interrupt
ES IE0.4 Enable Serial I/O interrupt
ET1 IE0.3 Enable Timer 1 interrupt
EX1 IE0.2 Enable External interrupt 1
ET0 IE0.1 Enable Timer 0 interrupt
EX0 IE0.0 Enable External interrupt 0
Interrupt Enable 1 (IE1) Register
EOB IE1.7 Enable OBE interrupt
EIB IE1.6 Enable IBF interrupt
EAD IE1.5 Enable ADC interrupt
EC4 IE1.4 Enable PCA module 4 interrupt
EC3 IE1.3 Enable PCA module 3 interrupt
EC2 IE1.2 Enable PCA module 2 interrupt
EC1 IE1.1 Enable PCA module 1 interrupt
EC0 IE1.0 Enable PCA module 0 interrupt
Interrupt Priority 0 (IP0) Register
PPC IP0.6 PCA interrupt priority
PT2 IP0.5 Timer 2 interrupt priority
PS IP0.4 Serial I/O interrupt priority
PT1 IP0.3 Timer 1 interrupt priority
PX1 IP0.2 External interrupt 1 priority
PT0 IP0.1 Timer 0 interrupt priority
PX0 IP0.0 External interrupt 0 priority
Interrupt Priority 1 (IP1) Register
POB IP1.7 OBE interrupt priority
PIB IP1.6 IBF interrupt priority
PAD IP1.5 ADC interrupt priority
PC4 IP1.4 PCA module 4 interrupt priority
PC3 IP1.3 PCA module 3 interrupt priority
PC2 IP1.2 PCA module 2 interrupt priority
PC1 IP1.1 PCA module 1 interrupt priority
PC0 IP1.0 PCA module 0 interrupt priority
PWCON.2 Counter enable and counter/prescaler
IP0.7 (reserved)
must be cleared by software
reset when Low
1998 Jun 04
25
Page 26
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
f
OSC
INTERNAL
BUS
1/2
PWMP
REG
8-BIT
PRESCALER
Figure 23. Block Diagram of PWMs
PCA Interrupt System
The PCA on most 80C51 family devices provides a single interrupt
source, EC (IE.6). The 8xC576 expands the flexibility of the PCA by
providing additional interrupt sources for each of the five PCA
modules, EC0 (IE1.0) through EC4 (IE1.4), in addition to the original
interrupt source EC (IE.6). Any of these sources can be enabled at
any time. It is possible for both a module source (EC0 through EC4)
to be enabled at the same time that the single source, EC, is
enabled. In this case, a module event will generate an interrupt for
both the module source and the single source, EC.
Priority Source Flag Vector
1 INT0 IE0 03H
highest priority
2 ADC ADF 3BH
3 TIMER 0 TF0 0BH
4 INT1 IE1 13H
5 TIMER 1 TF1 1BH
6 SERIAL RI,TI 23H
7 PCA0 CC0 43H
8 PCA1 CC1 4BH
9 PCA2 CC2 53H
10 PCA3 CC3 5BH
11 PCA4 CC4 63H
12 PCA ECF 33H
13 TIMER 2 TF2/EXF2 2BH
14 UPI IBF 6BH
15 UPI OBE 73H
lowest priority
Power Control (PCON) Register
SMOD1 PCON.7 double baud rate bit
SMOD0 PCON.6 SCON.7 access control
OSF PCON.5 oscillator fail flag
POF PCON.4 power off flag
LVF PCON.3 low voltage flag
WDTOF PCON.2 watchdog timeout flag
PD PCON.1 power down mode bit
IDL PCON.0 idle mode bit
UNIVERSAL PERIPHERAL INTERF ACE
UPI mode allows the 8XC576 to function as a slave processor
connected to a host CPU bus via port 0. The interface consists of
port 0 input and output buffer registers and the UPI control/status
register (UCS). UPI mode is enabled by setting the UPI enable bit
(UE) in the UCS. When operating in UPI mode, port 0 pins should
be programmed to High-Z (P0M1=1 and P0M2=0) by user firmware.
Access to port 0 is controlled by inputs WR
and WR are the external read and write strobes controlled by the
host CPU. CS
is the chip select input, normally a decoded address
, RD, CS, and A0. RD
8-BIT
UP
COUNTER
PWM0
PWM1
from the host CPU bus, which qualifies RD
have no effect when CS
8-BIT
DETECT
8-BIT
DETECT
OUTPUT
BUFFER
OUTPUT
BUFFER
P2.6
P2.7
SU00256A
and WR (these pins
=1). The A0 pin is an address input from the
host CPU which selects either the port 0 output buffer or the UCS
register to be output during a read operation. During a write
operation, the value of the A0 pin is latched in the AF flag in the
UCS register. The following is a summary of the UPI data control
inputs:
CS
RD WR A0
0 0 1 0 read port 0 output buffer,
clear OBF/set OBE
0 0 1 1 read UPI control/ status register
0 1 0 0 write data to input buffer set IBF, clear AF
0 1 0 1 write command to input buffer set IBF, AF
1 x x x disable input/output
UPI Control Status Register (UCS, Reset value = 00H)
UCS.7 ST7 User defined status bit
UCS.6 ST6 User defined status bit
UCS.5 ST5 User defined status bit
UCS.4 ST4 User defined status bit
UCS.3 UE UPI Enable bit – if UE=1, UPI is enabled
(read only AF, IBF, and OBE/OBF), if UE=0,
UPI is disabled and port 0 functions
normally .
UCS.2 AF Address Flag – contains status of the A0
(address) pin during the last write. If A0=0,
the input buffer should be interpreted as
data by the 8XC576 software, if A0=1, the
input buffer should be interpreted as a
command.
USC.1 IBF Input Buffer Full flag – set by hardware on
trailing (rising) edge of WR
when CS=0,
cleared by hardware when port 0 SFR is
read (by the 8XC576 software).
USC.0 OBE/OBF Output Buffer Full flag – set by hardware
during writes (by 8XC576 software) to the
port 0 SFR, set/cleared by hardware on the
trailing (rising) edge of RD
when CS=0 and
A0=0.
NOTE: This bit is defined as OBE (1=empty) when read by the
MCU, and, as OBF (—full) when read by the external host.
The IBF and OBF flag bits reflect the status of the input/output
buffers. The host CPU writes to the 8XC576 by driving data on the
external bus connected to port 0 and strobing the WR
=0. The WR strobe latches port 0 data in the input buffer and
CS
sets the IBF flag on the trailing (rising) edge. When the 8XC576
reads from port 0 in UPI mode, it reads from the input buffer and
pin while
1998 Jun 04
26
Page 27
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
clears the IBF. When the 8XC576 writes to port 0 in UPI mode, it
writes to the output buffer which sets the OBF and clears the OBE
flag. The host CPU can read the output buffer or the UCS register
enabling the port 0 drivers, the OBF flag is cleared and the OBE flag
is set when the output buffer is read.
When the UPI is enabled, the AF, IBF, and OBE/OBF flags are
read-only , and thus can only be modified by specific hardware
events.
The UPI runs in idle mode. It can interrupt the part out of Idle mode
for all UPI write and data read operations. It will not interrupt out of
idle mode for a UCS register read operation.
OSCILLA T OR CHARACTERISTICS
XTAL1 and XTAL2 are the input and output, respectively, of an
inverting amplifier . The pins can be configured for use as an on-chip
oscillator, as shown in the Logic Symbol, page 4.
To drive the device from an external clock source, XTAL1 should be
driven while XTAL2 is left unconnected. There are no requirements
on the duty cycle of the external clock signal, because the input to
the internal clock circuitry is through a divide-by-two flip-flop.
However, minimum and maximum high and low times specified in
the data sheet must be observed.
IDLE MODE
In idle mode, the CPU puts itself to sleep while all of the on-chip
peripherals stay active. The instruction to invoke the idle mode is the
last instruction executed in the normal operating mode before the
idle mode is activated. The CPU contents, the on-chip RAM, and all
of the special function registers remain intact during this mode. The
idle mode can be terminated either by any enabled interrupt (at
which time the process is picked up at the interrupt service routine
and continued), or by a hardware reset which starts the processor in
the same manner as a power-on reset. Also see UPI section.
POWER-DOWN MODE
In the power-down mode, the oscillator is stopped and the
instruction to invoke power-down is the last instruction executed.
Only the contents of the on-chip RAM are preserved. The control
bits for the reduced power modes are in the special function register
PCON. Power-down mode can be terminated with either a hardware
reset or external interrupt. With an external interrupt INT0
must be enabled and configured as level sensitive. Holding the pin
low restarts to oscillator and bringing the pin back high completes
the exit.
Power-down mode can be disabled by the DPD bit in the WDCON
register. Reset and waking up from power-down will also enable the
DPD bit, therefore, the DPD bit must be cleared again before the
power-down mode.
or INT1
DESIGN CONSIDERATIONS
At power-on, the voltage on VCC must come up with RST low for a
proper start-up.
Table 2 shows the state of I/O ports during low current operating
modes.
Table 2. External Pin Status During Idle and Power-Down Modes
MODE PROGRAM MEMORY ALE PSEN PORT 0 PORT 1 PORT 2 PORT 3
Idle Internal 1 1 Data Data Data Data
Idle External 1 1 Float Data Address Data
Power-down Internal 0 0 Data Data Data Data
Power-down External 0 0 Float Data Data Data
1998 Jun 04
27
Page 28
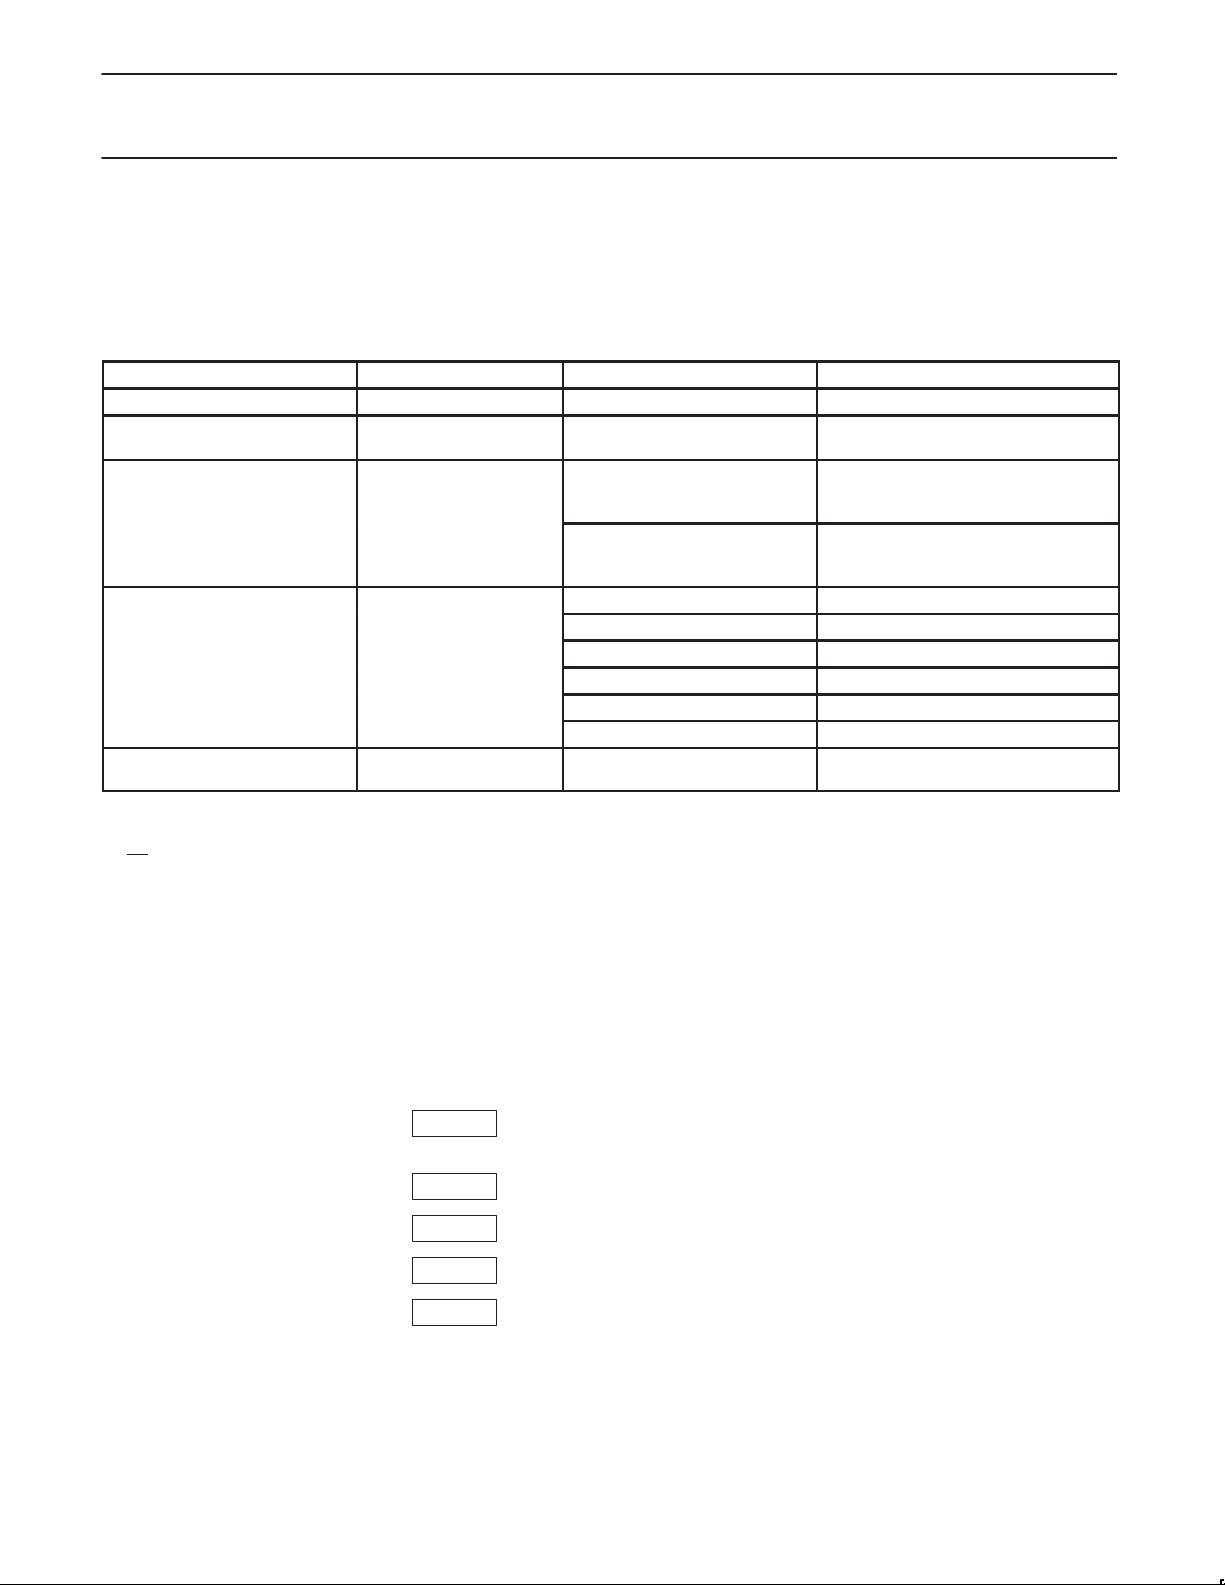
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
ROM CODE SUBMISSION
When submitting ROM code for the 83C576, the following must be specified:
1. 8k byte user ROM data
2. 32 byte ROM encryption key
3. ROM security bits
4. The watchdog timer parameters. (See Watchdog Timer Specifications for definition of WDL and WDCON bits.)
83C576/87C576
ADDRESS
0000H to 1FFFH DATA 7:0 User ROM Data
2000H to 201FH KEY 7:0 ROM Encryption Key
2020H SEC
2030H WDCON
2031H WDL 7:0 Watchdog autoload value
Security Bit 1: When programmed, this bit has two effects on masked ROM parts:
1. External MOVC is disabled, and
2. EA is latched on Reset.
Security Bit 2: When programmed, this bit inhibits Verify User ROM.
If the ROM code file does not include the options, the following information must be included with the ROM code.
For each of the following, check the appropriate box and send to Philips along with the code:
Security Bit #1:
Security Bit #2:
Encryption:
Watchdog/T imer Modes:
Enabled Disabled
Enabled Disabled
No Yes If Yes, must send key file.
CONTENT BIT(S) COMMENT
FFH = no encryption
0 ROM Security Bit 1
0 = enable security
1 = disable security
1 ROM Security Bit 2
0 = enable security
1 = disable security
7:5 PRE2:0
4 LVRE
3 OFRE
2 DPD
1 WDRUN = 0, not ROM coded
0 WDMOD
(see specification)
Watchdog Mode Timer Mode
Prescaler Value:
Autoload Value (range 0–255):
Low Voltage Reset (Value 0 or 1):
Oscillator Fail Reset (Value 0 or 1):
Power-Down (Value 0 or 1):
1998 Jun 04
(Value = 64, 128, 256, 512, 1024, 2048, 4096, 8192)
Value
28
Page 29
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
ABSOLUTE MAXIMUM RATINGS
Operating temperature under bias –55 to +125 °C
Storage temperature range –65 to +150 °C
Voltage on EA/VPP pin to V
Voltage on any other pin to V
Maximum IOL per I/O pin 15 mA
Power dissipation (based on package heat transfer limitations, not device power consumption) 1.5 W
NOTES:
1. Stresses above those listed under Absolute Maximum Ratings may cause permanent damage to the device. This is a stress rating only and
functional operation of the device at these or any conditions other than those described in the AC and DC Electrical Characteristics section
of this specification is not implied.
2. This product includes circuitry specifically designed for the protection of its internal devices from the damaging effects of excessive static
charge. Nonetheless, it is suggested that conventional precautions be taken to avoid applying greater than the rated maxima.
3. Parameters are valid over operating temperature range unless otherwise specified. All voltages are with respect to V
noted.
SS
SS
1, 2, 3
PARAMETER
RATING UNIT
0 to +13.0 V
–0.5 to +6.5 V
unless otherwise
SS
1998 Jun 04
29
Page 30
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
DC ELECTRICAL CHARACTERISTICS
T
= 0°C to +70°C, –40°C to +85°C, and –40°C to +125°C; VCC = 5V ±10%, VSS = 0V
amb
TEST LIMITS
SYMBOL PARAMETER CONDITIONS MIN TYP
V
IL
V
IL1
V
IL2
V
IH
V
IH1
HYS Hysteresis voltage (Port 1) 200 mV
V
OL
V
OL1
V
OH
V
OH1
V
OH2
V
IO
V
CR
I
IL
I
IH
I
L2
I
LA
I
CC
R
RST
V
LOW
C
IO
NOTES:
1. Typical ratings are not guaranteed. The values listed are at room temperature, 5V.
2. Capacitive loading on ports 0 and 2 may cause spurious noise to be superimposed on the V
to external bus capacitance discharging into the port 0 and port 2 pins when these pins make 1-to-0 transitions during bus operations. In the
worst cases (capacitive loading > 100pF), the noise pulse on the ALE pin may exceed 0.8V . In such cases, it may be desirable to qualify
ALE with a Schmitt Trigger, or use an address latch with a Schmitt Trigger STROBE input. I
single output sinks more than 5mA and no more than two outputs exceed the test conditions.
3. Capacitive loading on ports 0 and 2 may cause the V
address bits are stabilizing.
4. Pins of ports 1, 2 and 3 source a transition current when they are being externally driven from 1 to 0. The transition current reaches its
maximum value when V
5. I
CC
6. See Figures 34 through 37 for I
7. Load capacitance for port 0, ALE, and PSEN
8. Under steady state (non-transient) conditions, I
If I
test conditions.
9. 20pF MAX for CERDIP package; 15pF MAX for all other packages.
Input low voltage (except Port 1, EA) –0.5 0.2VCC–0.1 V
Input low voltage (EA) –0.5 0.2VCC–0.45 V
Input low voltage (Port 1) –0.5 0.3V
Input high voltage (except Port 1, XTAL1, RST) IIH < 2mA 0.2VCC+0.9 VCC+0.5 V
Input high voltage (XTAL1, RST, Port 1) IIH < 2mA 0.7V
CC
Output voltage low (Ports 1, 2, 3) IOL = 1.6mA 0.45 V
Output voltage low (Ports 0, ALE, PSEN
)
IOL = 3.2mA 0.45 V
Output voltage high (Ports 1, 2, 3 in push-pull mode) IOH = –1.6mA VCC–1.0 V
Output voltage high (Port 0, ALE, PSEN) IOH = –3.2mA VCC–0.7 V
Output voltage high in weak pullup mode (Port 0, 2, 3) IOH = –10µA VCC–1.0 V
Offset voltage comparator inputs –35 +35 mV
Common mode range comparator inputs 0 V
Logical 0 input current (Ports 0, 2, 3) (weak pull-up) VIN = 0.45V –250 µA
Input pulldown current (Port 0, Port2 in open drain mode) 0.45 < VIN < V
Input leakage current (EA, P0. 2. 3 High-Z) 0.45 < VIN < V
Input leakage current comparator/ADC inputs 0 < VIN < V
Power supply current:
Active mode @ 16MHz
7
5
See note 6
CC
CC
CC
2 40 µA
–10 +10 µA
–1.0 +1.0 µA
Idle mode @ 16MHz
Power-down mode
Internal reset pull-up resistor VIN = 0V 50 200 kΩ
Low VCC detect voltage 3.75 4.25 V
Pin capacitance
MAX at other frequencies can be determined from Figure 33.
Maximum I
Maximum I
Maximum total I
exceeds the test condition, VOL may exceed the related specification. Pins are not guaranteed to sink current greater than the listed
OL
per port pin: 10mA
OL
per 8-bit port: 26mA
OL
9
is between VIH and VIL.
IN
test conditions.
CC
for all outputs: 71mA
OL
f = 1MHz 15 pF
s of ALE and ports 1 and 3. The noise is due
OL
can exceed these conditions provided that no
OL
on ALE and PSEN to momentarily fall below the 0.9VCC specification when the
OH
= 100pF, load capacitance for all other outputs = 80pF.
must be externally limited as follows:
OL
83C576/87C576
1
20
8
5
MAX UNIT
CC
VCC+0.5 V
CC
30
12
mA
mA
75
V
V
µA
1998 Jun 04
30
Page 31
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
A/D CONVERTER DC ELECTRICAL CHARACTERISTICS
T
= 0°C to +70°C, –40°C to +85°C, and –40°C to +125°C; VCC = 5V ±10%, VSS = 0V
amb
TEST LIMITS
SYMBOL PARAMETER CONDITIONS MIN MAX UNIT
Static Characteristics
R Resolution Monotonic with no missing codes 10 Bits
IL
DL
FS
OS
e
e
e
e
Integral non-linearity error
Differential non-linearity error
Full Scale error
Offset error
2, 8
2, 6, 8
Dynamic Characteristics
t
ADC
t
ADS
Conversion time (including sampling time) 48t
Sampling tme 8t
Analog Input Characteristics
AV
C
M
C
IN
IA
CTC
t
Analog input voltage AVSS – 0.2 AVDD + 0.2 V
Analog input capacitance 15 pF
Channel-to-channel matching
Crosstalk between inputs of port 1
Power Requirements
AVCC/V
AI
CC
Analog supply and reference voltage AVCC = VCC ± 0.2 4.0 6.0 V
REF+
Analog supply current: operating: (16MHz) AVCC = 6.0V 1.2 mA
NOTES:
1. The following condition must not be exceeded: V
2. Conditions: AV
3. The differential non-linearity (DL
= 0V; AVCC = 4.997V; VCC = 5.0V.
SS
4. The ADC is monotonic; there are no missing codes.
5. The integral non-linearity (IL
appropriate adjustment of gain and offset error. (See Figure 24).
6. The offset error (OS
a straight line which fits the ideal transfer curve. (See Figure 24).
e
) is the peak difference between the center of the steps of the actual and the ideal transfer curve after
e
) is the absolute difference between the straight line which fits the actual transfer curve (after removing gain error), and
7. Guaranteed by design.
8. To meet Error Specification, analog input voltage must be less than 1V/ms.
(AV
ń1023) 1000
Slew Rate
MAX
+
CC
4 (12ńOsc Freq (MHz))
For 16MHz @ 5.0V slew rate = 1.6V/ms.
2, 5, 8
2, 3, 4, 7, 8
7
7
– 0.2V < AVDD < VDD + 0.2V.
DD
) is the difference between the actual step width and the ideal step width. (See Figure 24).
e
0–100kHz –60 dB
(Vńms)
83C576/87C576
±2 LSB
±1 LSB
±3 LSB
±2 LSB
CY
CY
±1 LSB
µs
µs
1998 Jun 04
31
Page 32
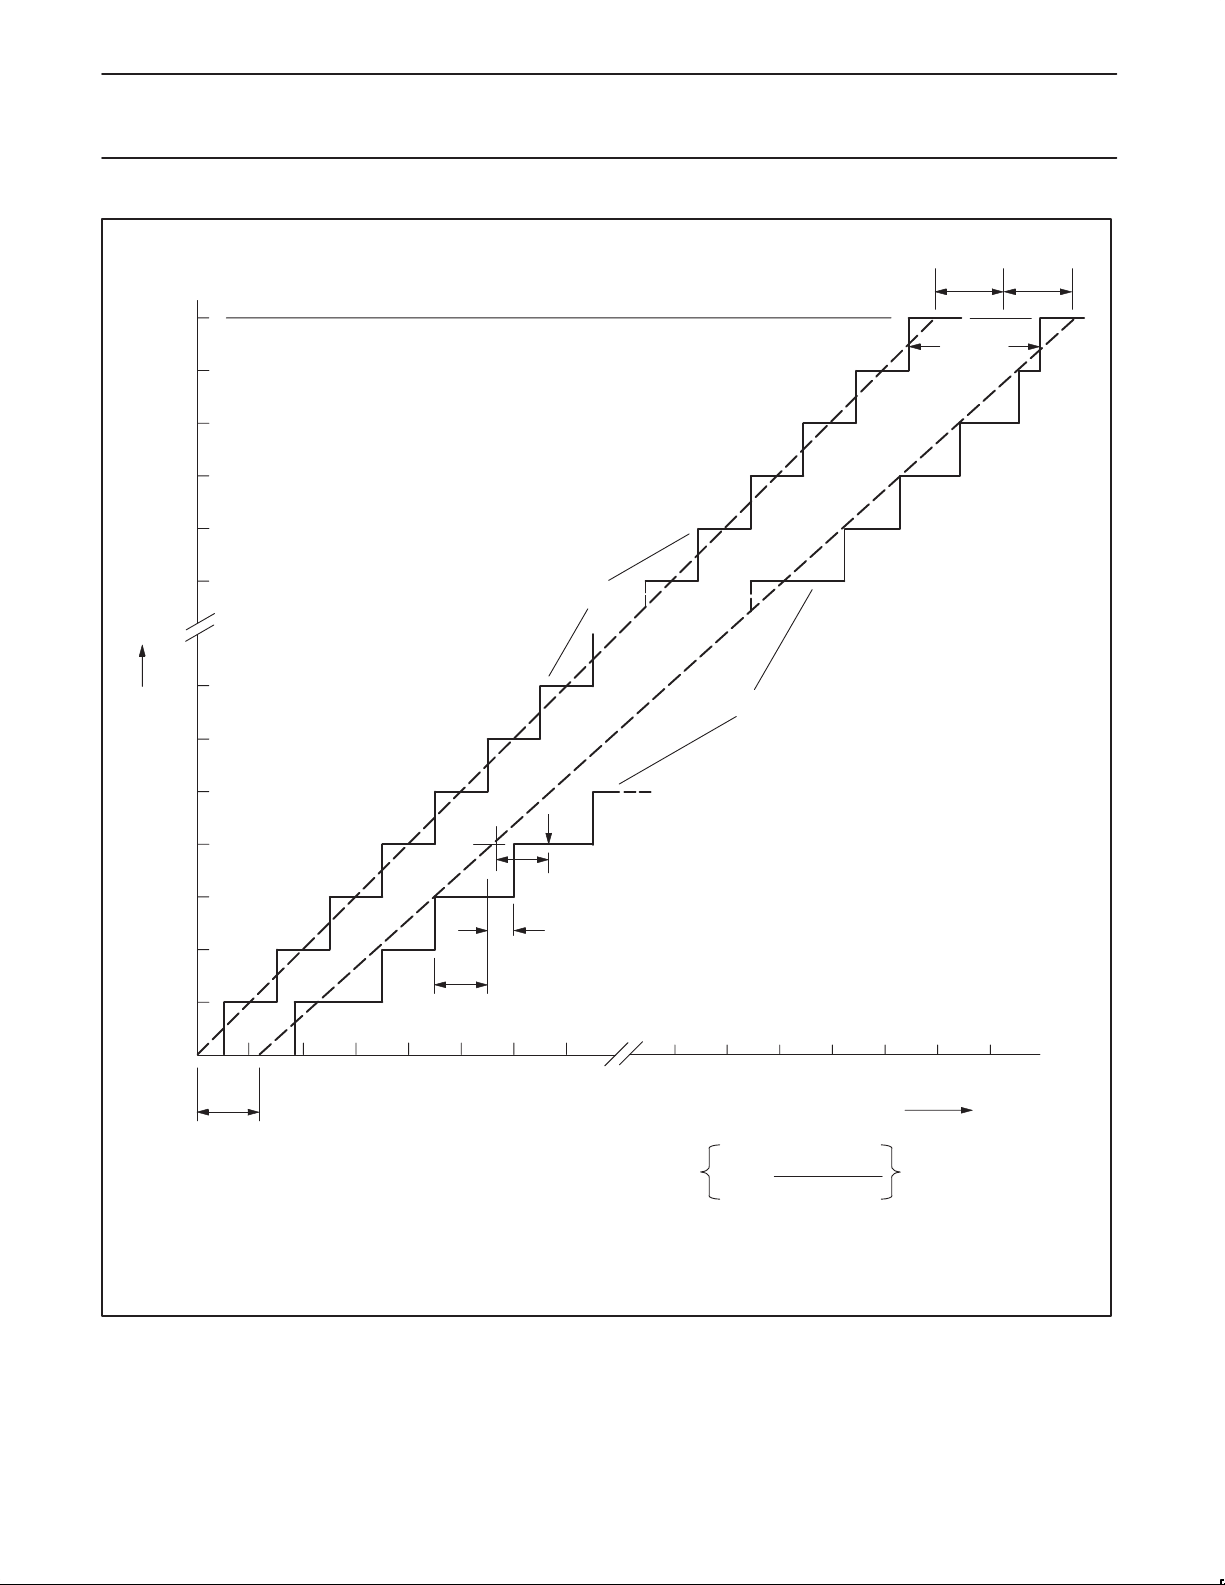
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
Code
Out
1023
1022
1021
1020
1019
1018
Offset
error
OS
Full Scale
(2)
7
6
5
(5)
4
(4)
3
(1)
e
error
FS
Gain
error
G
e
e
2
1
0
1 2 3 4 5 6 7 1018 1019 1020 1021 1022 1023 1024
Offset
error
OS
e
(1) Example of an actual transfer curve.
(2) The ideal transfer curve.
(3) Differential non-linearity (DL
(4) Integral non-linearity (IL
(5) Center of a step of the actual transfer curve.
).
e
).
e
(3)
1 LSB
(ideal)
1 LSB =
Figure 24. ADC Conversion Characteristic
AV
AVIN (LSB
REF+
1024
– AV
ideal
REF–
)
SU00710
1998 Jun 04
32
Page 33
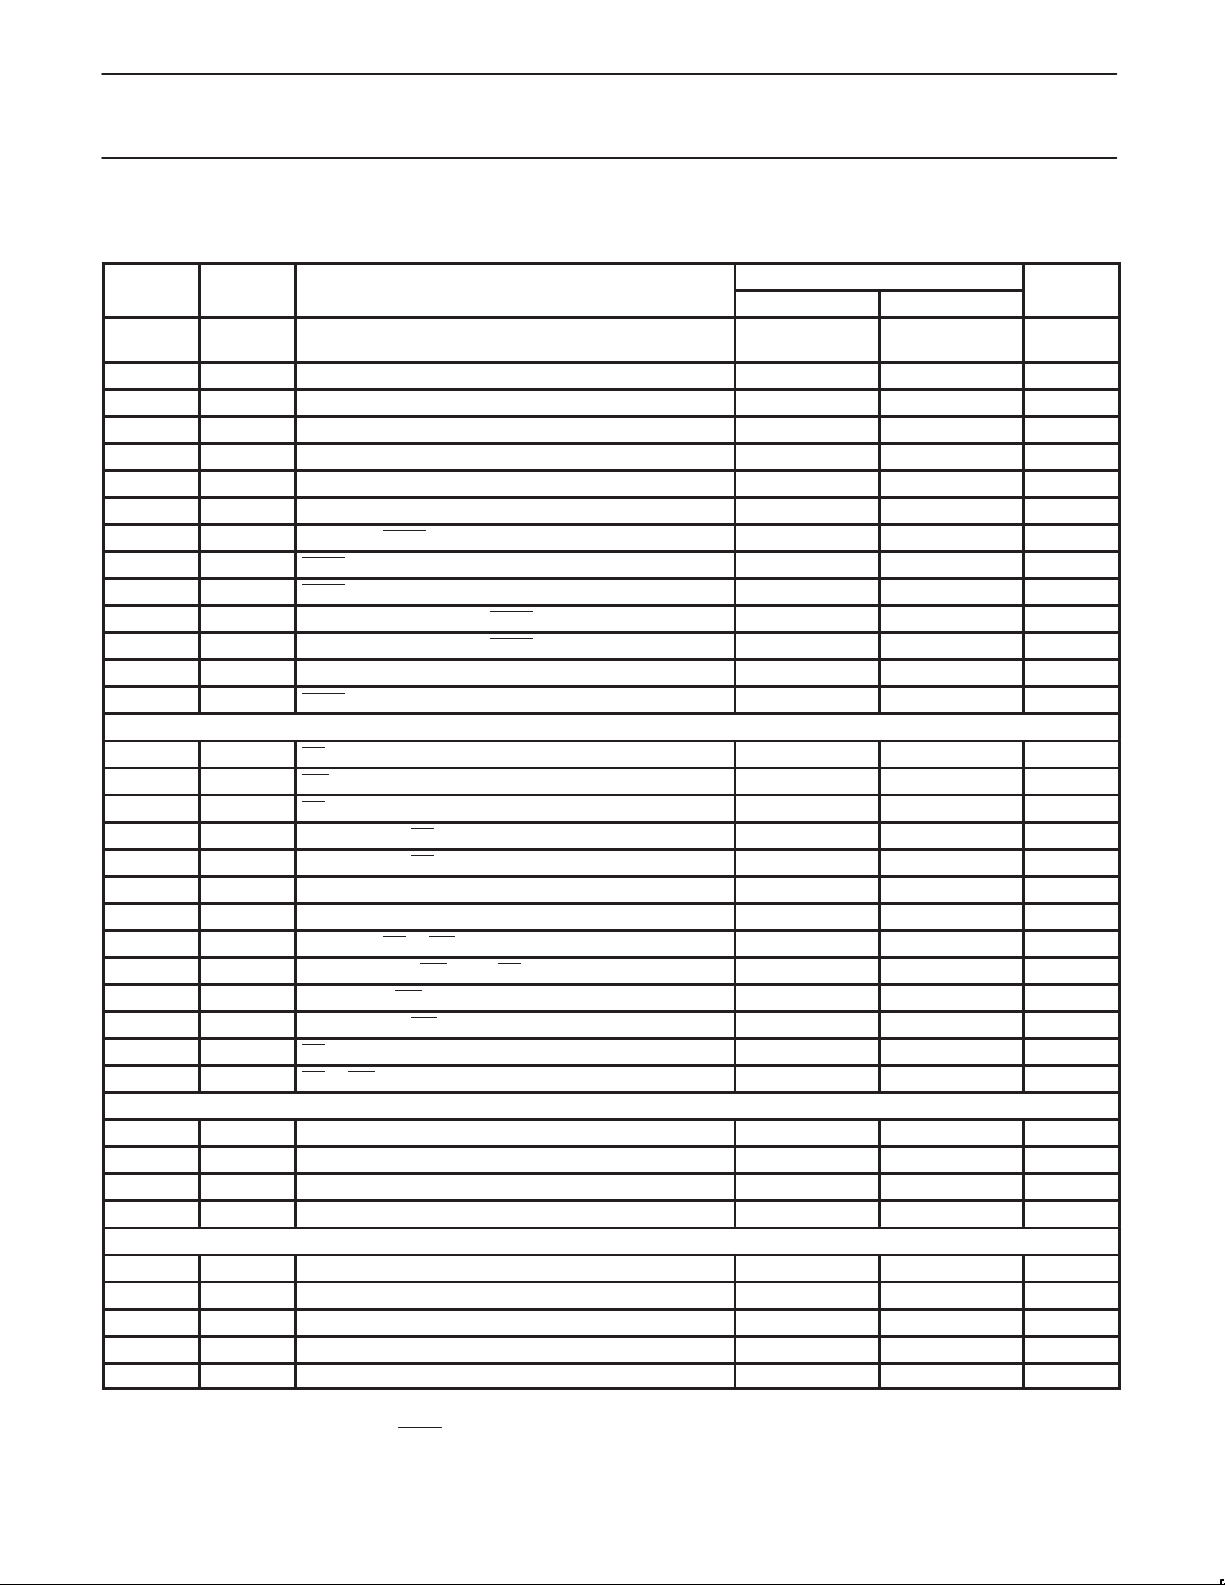
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
AC ELECTRICAL CHARACTERISTICS
T
= 0°C to +70°C, –40°C to +85°C, and –40°C to +125°C; VCC = 5V ±10%, VSS = 0V
amb
SYMBOL FIGURE PARAMETER MIN MAX UNIT
1/t
CLCL
25 Oscillator frequency: Speed Version
8XC576 E 6 16 MHz
OSCF Oscillator fail detect frequency 0.6 5.5 MHz
TR Comparator response time 10 µs
t
LHLL
t
AVLL
t
LLAX
t
LLIV
t
LLPL
t
PLPH
t
PLIV
t
PXIX
t
PXIZ
t
AVIV
t
PLAZ
25 ALE pulse width 2t
25 Address valid to ALE low t
25 Address hold after ALE low t
25 ALE low to valid instruction in 4t
25 ALE low to PSEN low t
25 PSEN pulse width 3t
25 PSEN low to valid instruction in 3t
25 Input instruction hold after PSEN 0 ns
25 Input instruction float after PSEN t
25 Address to valid instruction in 5t
25 PSEN low to address float 10 ns
Data Memory
t
RLRH
t
WLWH
t
RLDV
t
RHDX
t
RHDZ
t
LLDV
t
AVDV
t
LLWL
t
AVWL
t
QVWX
t
WHQX
t
RLAZ
t
WHLH
26, 27 RD pulse width 6t
26, 27 WR pulse width 6t
26, 27 RD low to valid data in 5t
26, 27 Data hold after RD 0 ns
26, 27 Data float after RD 2t
26, 27 ALE low to valid data in 8t
26, 27 Address to valid data in 9t
26, 27 ALE low to RD or WR low 3t
26, 27 Address valid to WR low or RD low 4t
26, 27 Data valid to WR transition t
26, 27 Data hold after WR t
26, 27 RD low to address float 0 ns
26, 27 RD or WR high to ALE high t
External Clock
t
CHCX
t
CLCX
t
CLCH
t
CHCL
29 High time 20 ns
29 Low time 20 ns
29 Rise time 20 ns
29 Fall time 20 ns
Shift Register
t
XLXL
t
QVXH
t
XHQX
t
XHDX
t
XHDV
28 Serial port clock cycle time 12t
28 Output data setup to clock rising edge 10t
28 Output data hold after clock rising edge 2t
28 Input data hold after clock rising edge 0 ns
28 Clock rising edge to input data valid 10t
NOTES:
1. Parameters are valid over operating temperature range unless otherwise specified.
2. Load capacitance for port 0, ALE, and PSEN
= 100pF, load capacitance for all other outputs = 80pF.
3. Interfacing the 83C576/87C576 to devices with float times up to 45ns is permitted. This limited bus contention will not cause damage to Port
0 drivers.
1, 2
VARIABLE CLOCK
–40 ns
CLCL
–40 ns
CLCL
–30 ns
CLCL
–100 ns
CLCL
–30 ns
CLCL
–45 ns
CLCL
–105 ns
CLCL
–25 ns
CLCL
–105 ns
CLCL
–100 ns
CLCL
–100 ns
CLCL
–165 ns
CLCL
–60 ns
CLCL
–150 ns
CLCL
–165 ns
CLCL
–50 3t
CLCL
–130 ns
CLCL
–50 ns
CLCL
–50 ns
CLCL
–40 t
CLCL
CLCL
–133 ns
CLCL
–60 ns
CLCL
+50 ns
CLCL
+40 ns
CLCL
–133 ns
CLCL
ns
1998 Jun 04
33
Page 34
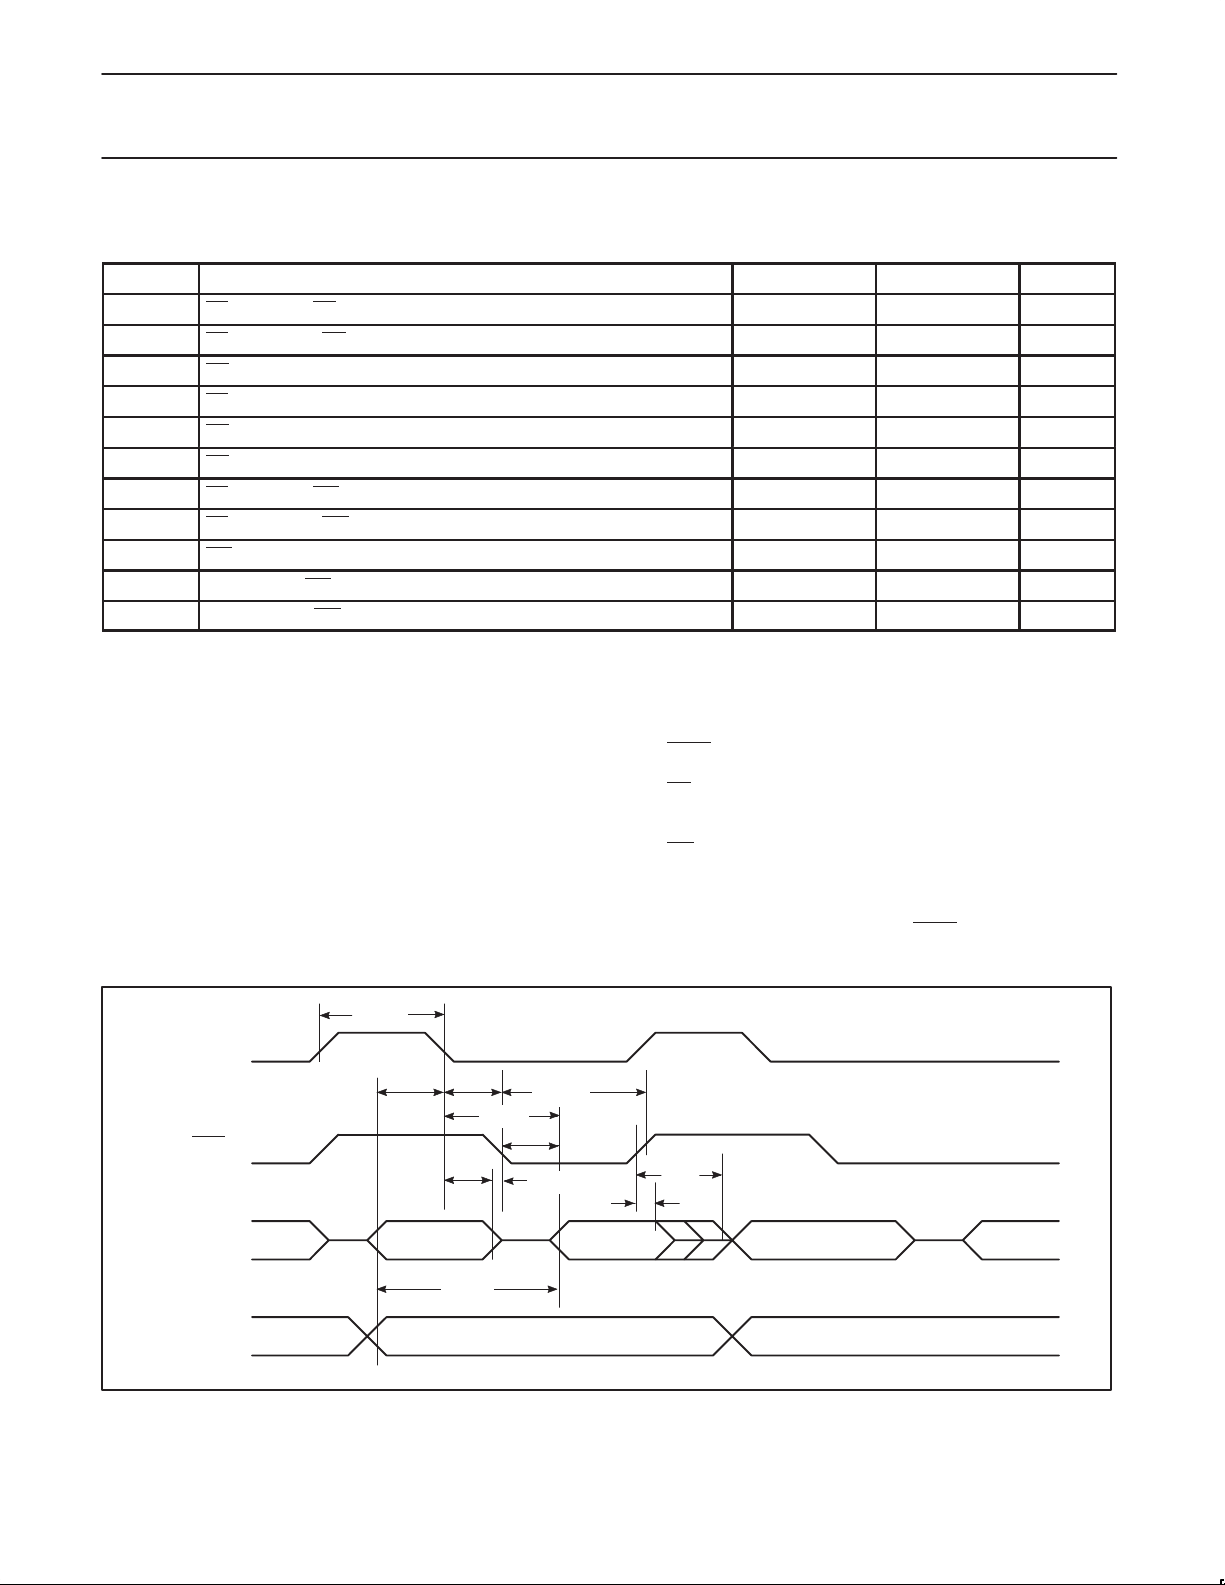
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
UPI AC ELECTRICAL CHARACTERISTICS
T
= 0°C to +70°C, –40°C to +85°C, and –40°C to +125°C; VCC = 5V ±10%, VSS = 0V
amb
SYMBOL
t
AR
t
RA
t
RR
t
AD
t
RD
t
DF
t
AW
t
WA
t
WW
t
DW
t
WD
CS, A setup to RD 0 ns
CS, A hold after RD 35 ns
RD pulse width 35 ns
CS, A to data out delay 45 ns
RD to data out delay 35 ns
RD to data float delay (guaranteed by design) 30 ns
CS, A setup to WR 0 ns
CS, A hold after WR 15 ns
WR pulse width 45 ns
Data setup to WR 5 ns
Data hold after WR 25 ns
PARAMETER MIN MAX UNIT
83C576/87C576
EXPLANATION OF THE AC SYMBOLS
Each timing symbol has five characters. The first character is always
‘t’ (= time). The other characters, depending on their positions,
indicate the name of a signal or the logical status of that signal.
The designations are:
A – Address
C – Clock
D – Input data
H – Logic level high
I – Instruction (program memory contents)
L – Logic level low, or ALE
t
ALE
PSEN
PORT 0
LHLL
t
t
AVLL
LLPL
t
LLAX
A0–A7 A0–A7
t
AVIV
t
LLIV
t
PLIV
t
PLPH
t
PLAZ
t
PXIX
INSTR IN
P – PSEN
Q – Output data
signal
R–RD
t – Time
V – Valid
W– WR
signal
X – No longer a valid logic level
Z – Float
Examples: t
t
PXIZ
= Time for address valid to ALE low.
AVLL
t
=Time for ALE low to PSEN low.
LLPL
1998 Jun 04
PORT 2
A0–A15 A8–A15
SU00006
Figure 25. External Program Memory Read Cycle
34
Page 35
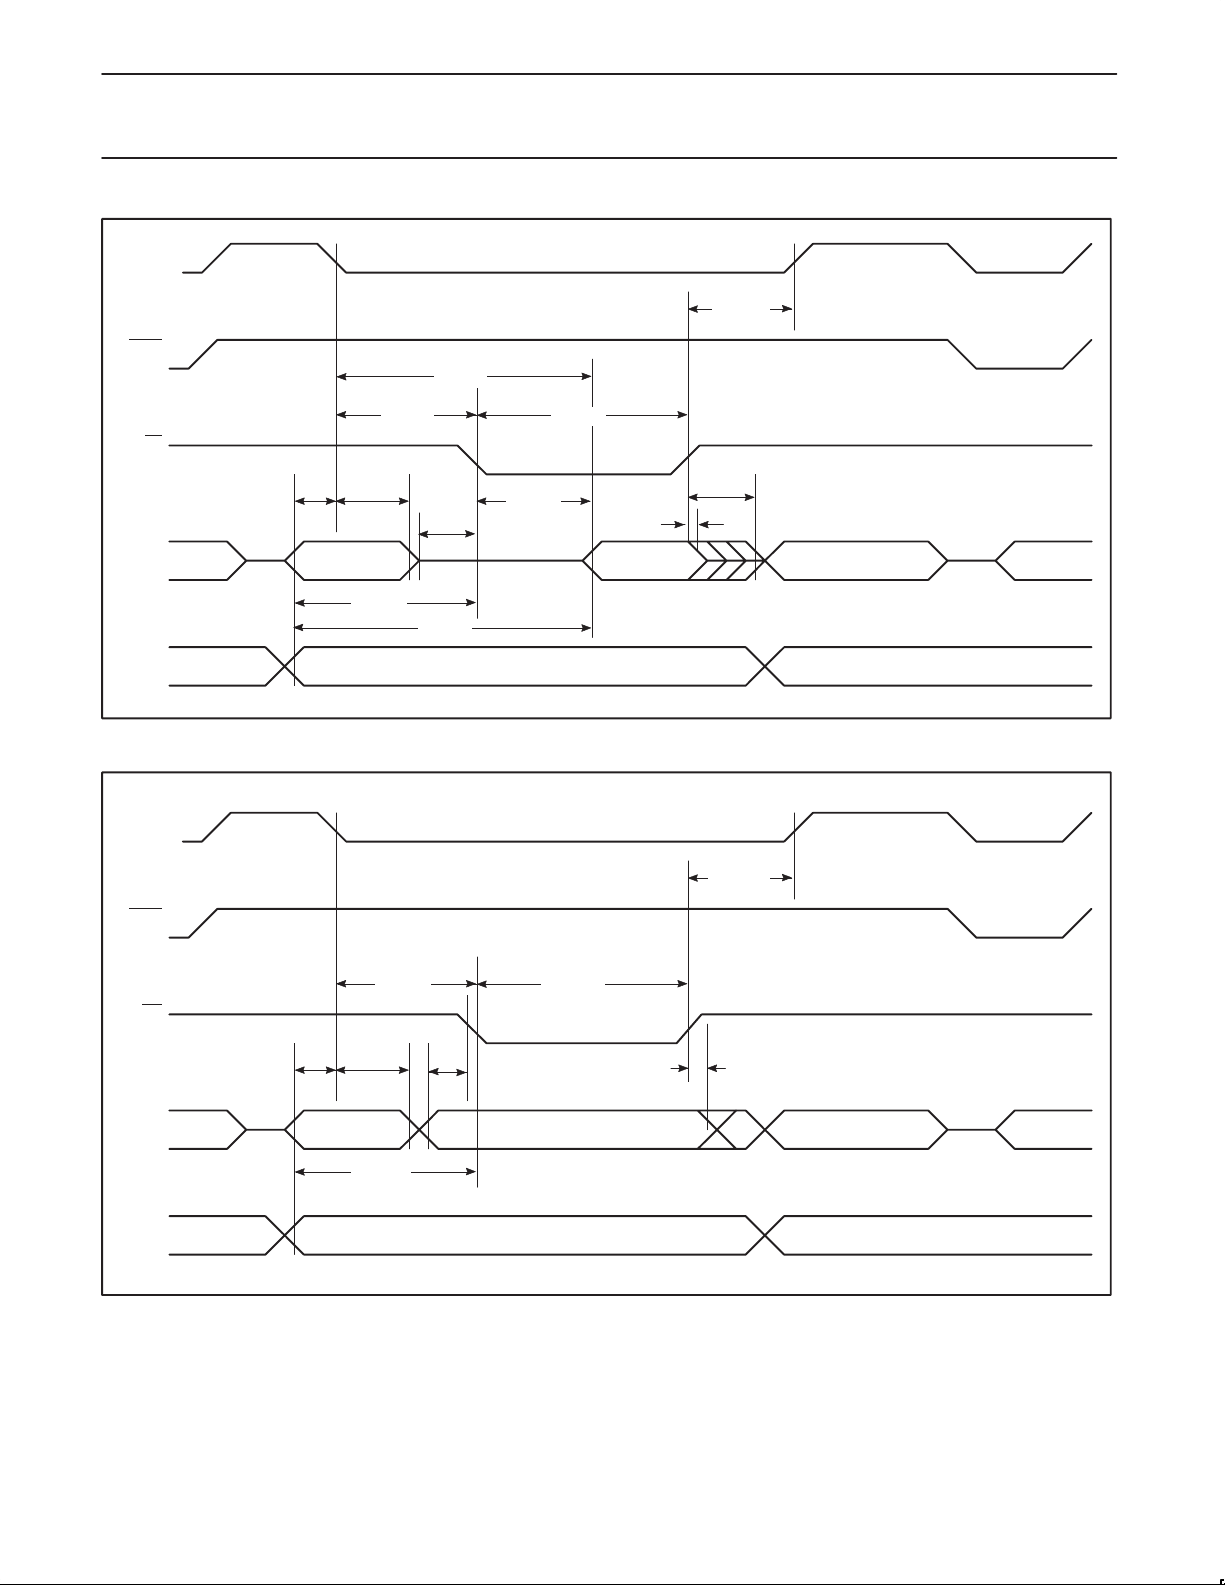
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
ALE
PSEN
t
LLDV
PORT 0
PORT 2
RD
t
AVLL
t
LLAX
A0–A7
FROM RI OR DPL
t
AVWL
t
LLWL
t
RLAZ
t
AVDV
P2.0–P2.7 OR A8–A15 FROM DPF A0–A15 FROM PCH
t
RLDV
t
RLRH
t
WHLH
t
RHDZ
t
RHDX
DATA IN A0–A7 FROM PCL INSTR IN
83C576/87C576
ALE
PSEN
WR
PORT 0
PORT 2
t
AVLL
t
LLAX
A0–A7
FROM RI OR DPL
t
AVWL
Figure 26. External Data Memory Read Cycle
t
WHLH
t
LLWL
t
QVWX
P2.0–P2.7 OR A8–A15 FROM DPF A0–A15 FROM PCH
t
WLWH
t
WHQX
DATA OUT A0–A7 FROM PCL INSTR IN
Figure 27. External Data Memory Write Cycle
SU00025
SU00069
1998 Jun 04
35
Page 36
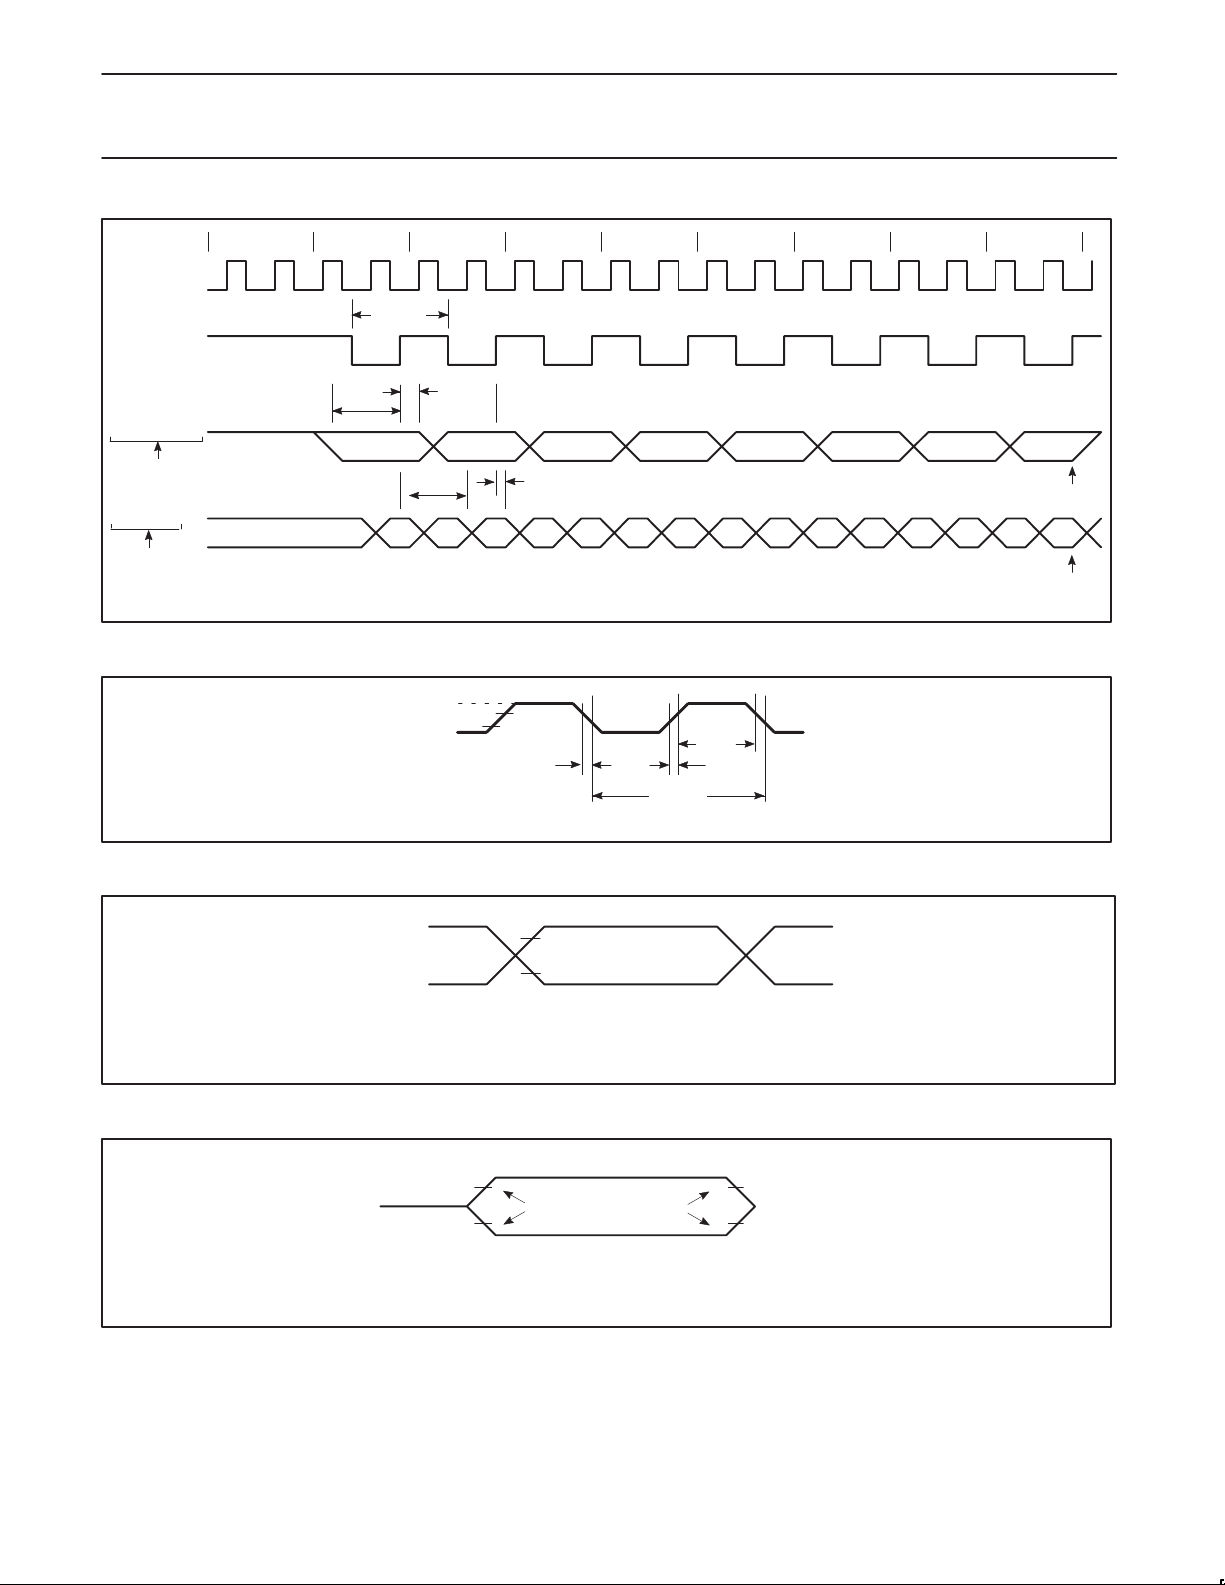
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
INSTRUCTION
ALE
CLOCK
OUTPUT DATA
WRITE TO SBUF
INPUT DATA
CLEAR RI
012345678
t
XLXL
t
t
QVXH
t
XHDV
VALID VALID VALID VALID VALID VALID VALID VALID
XHQX
1230 4567
t
XHDX
SET TI
SET RI
SU00027
Figure 28. Shift Register Mode Timing
VCC–0.5
0.45V
0.7V
CC
0.2VCC–0.1
t
CHCL
t
CLCX
t
CLCL
t
CHCX
t
CLCH
SU00009
Figure 29. External Clock Drive
VCC–0.5
0.45V
NOTE:
AC inputs during testing are driven at VCC –0.5 for a logic ‘1’ and 0.45V for a logic ‘0’.
Timing measurements are made at VIH min for a logic ‘1’ and VIL max for a logic ‘0’.
0.2V
0.2V
CC
CC
+0.9
–0.1
SU00010
Figure 30. AC Testing Input/Output
V
+0.1V
LOAD
V
LOAD
LOAD
–0.1V
V
NOTE:
For timing purposes, a port is no longer floating when a 100mV change from load voltage occurs,
and begins to float when a 100mV change from the loaded V
TIMING
REFERENCE
POINTS
OH/VOL
V
–0.1V
OH
+0.1V
V
OL
level occurs. IOH/IOL ≥ ±20mA.
SU00011
Figure 31. Float Waveform
1998 Jun 04
36
Page 37
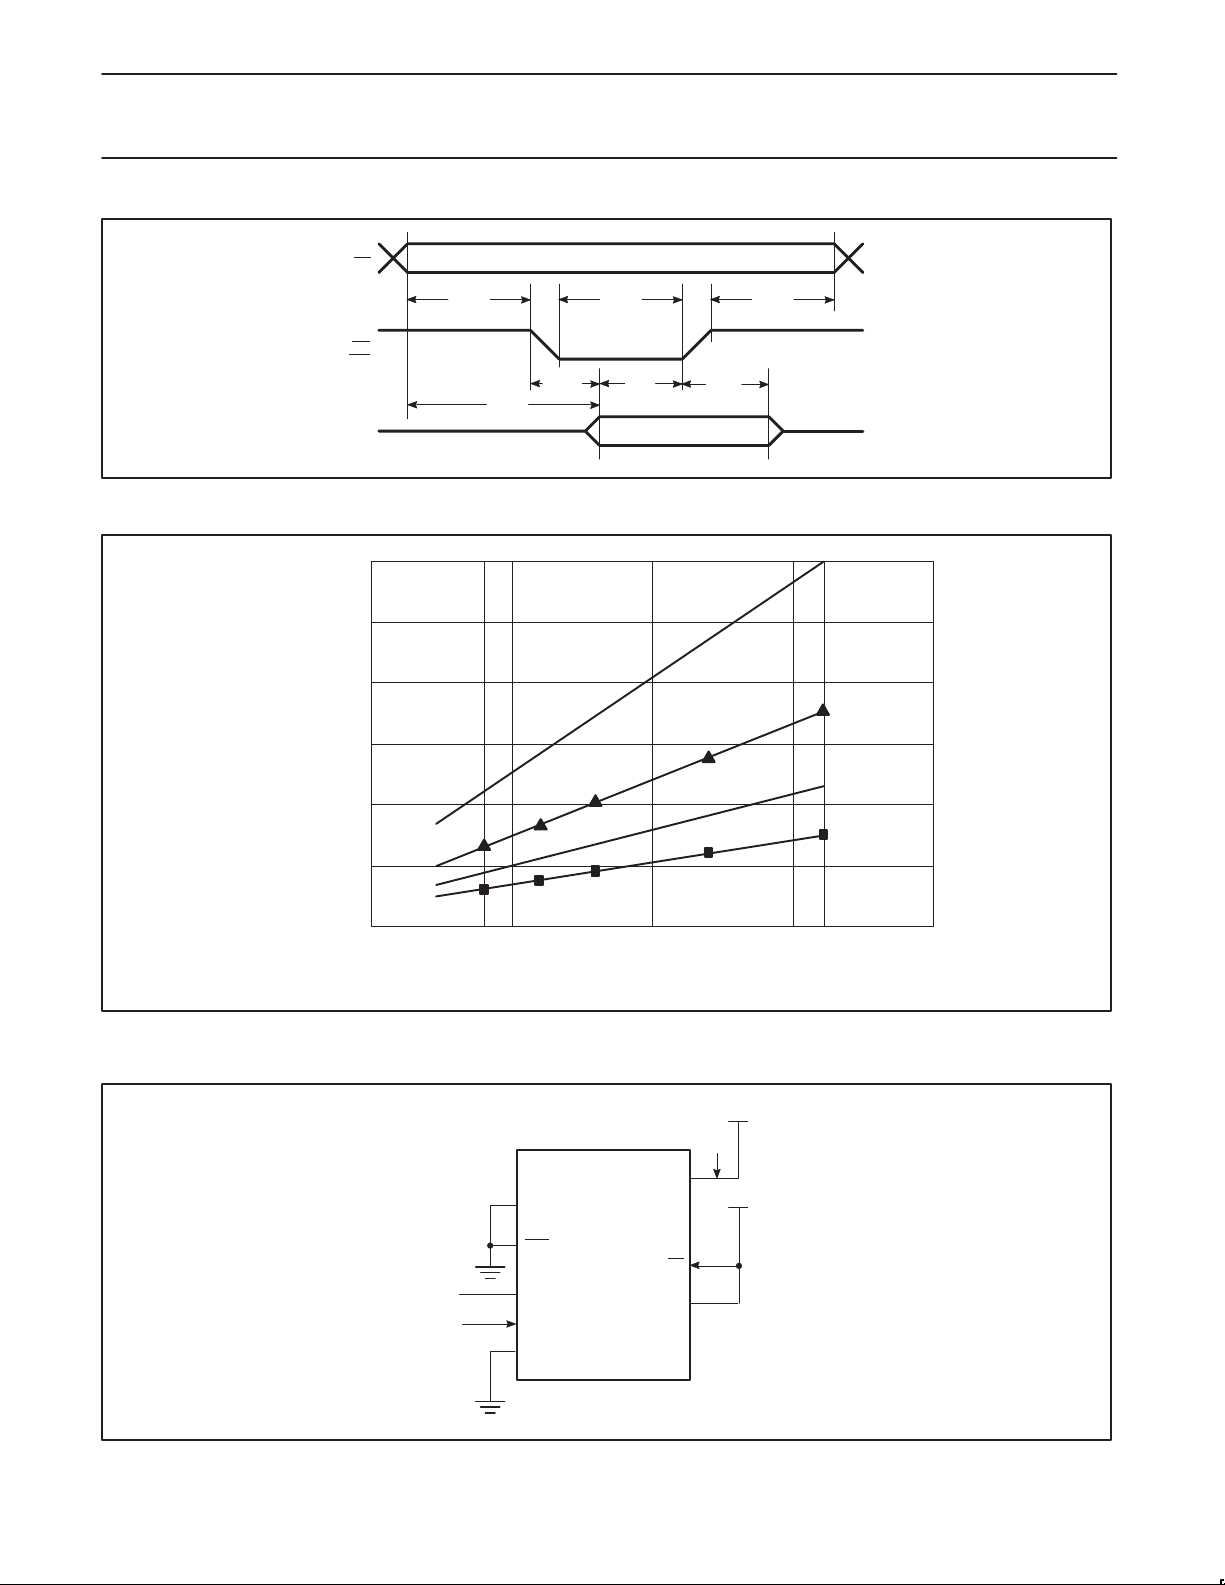
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
AO, CS
t
AR
t
AW
RD
WR
t
t
D0–D7
Figure 32. UPI Read/Write Cycles
RD
AD
t
t
RR
WW
t
DW
t
t
DF
WD
t
t
RA
WA
SU00518
83C576/87C576
30
25
20
15
I
(mA)
CC
10
5
0
045 10 151620
FREQUENCY (MHz)
MAX ACTIVE
TYP ACTIVE
MAX IDLE
TYP IDLE
SU00245
Figure 33. ICC vs. FREQ
Valid only within frequency specifications of the device under test
V
CC
I
CC
1998 Jun 04
(NC)
CLOCK SIGNAL
V
AV
SS
RST
XTAL2
XTAL1
V
SS
CC
EA
AV
CC
SU00661
V
CC
Figure 34. ICC Test Condition, Active Mode
All other pins are disconnected
37
Page 38
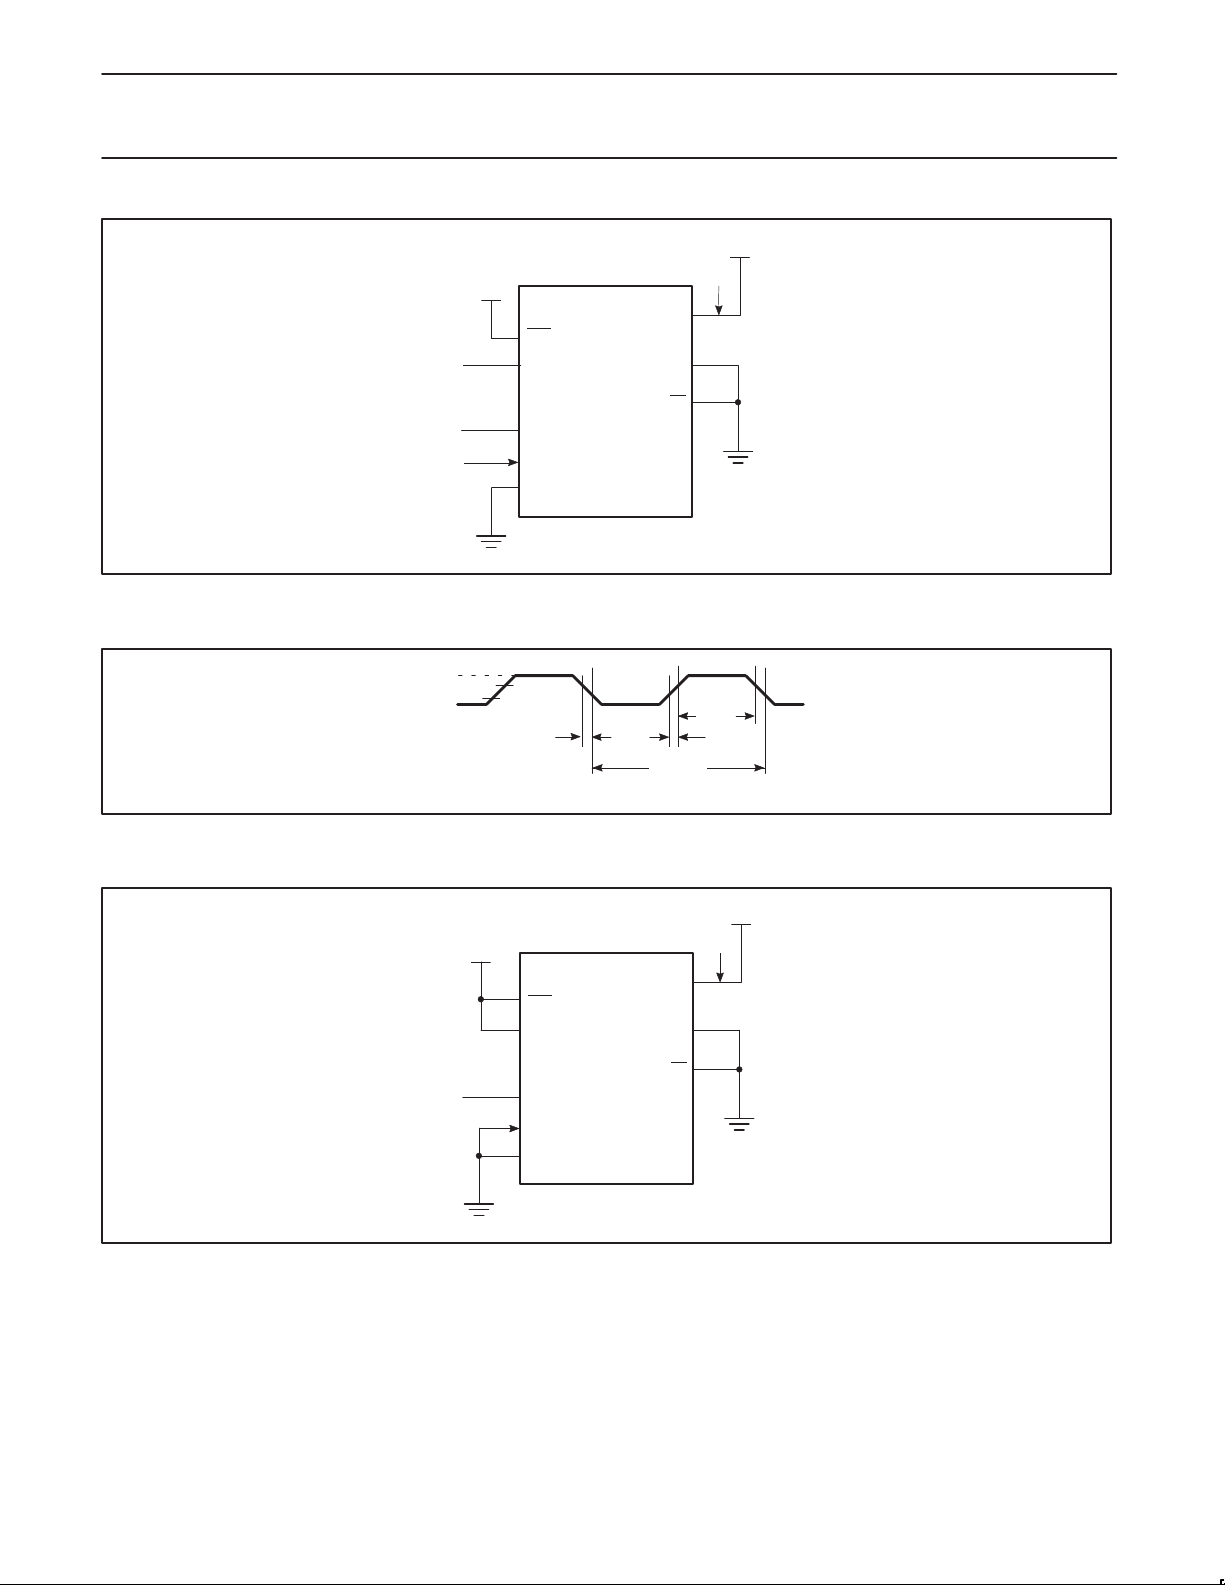
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
V
CC
RST
V
CC
I
CC
V
CC
83C576/87C576
AV
CC
(NC)
CLOCK SIGNAL
AV
CC
XTAL2
XTAL1
V
SS
AV
SS
EA
SU00662
Figure 35. ICC Test Condition, Idle Mode
All other pins are disconnected
VCC–0.5
0.45V
0.7V
CC
0.2VCC–0.1
t
CHCL
t
CLCX
t
CLCL
t
CHCX
t
CLCH
SU00009
Figure 36. Clock Signal Waveform for ICC Tests in Active and Idle Modes
t
(NC)
= t
CLCH
V
CC
RST
AV
CC
XTAL2
XTAL1
V
SS
CHCL
= 5ns
V
AV
CC
SS
EA
I
CC
V
CC
1998 Jun 04
SU00663A
Figure 37. ICC Test Condition, Power Down Mode
All other pins are disconnected. V
= 2V to 5.5V
CC
38
Page 39
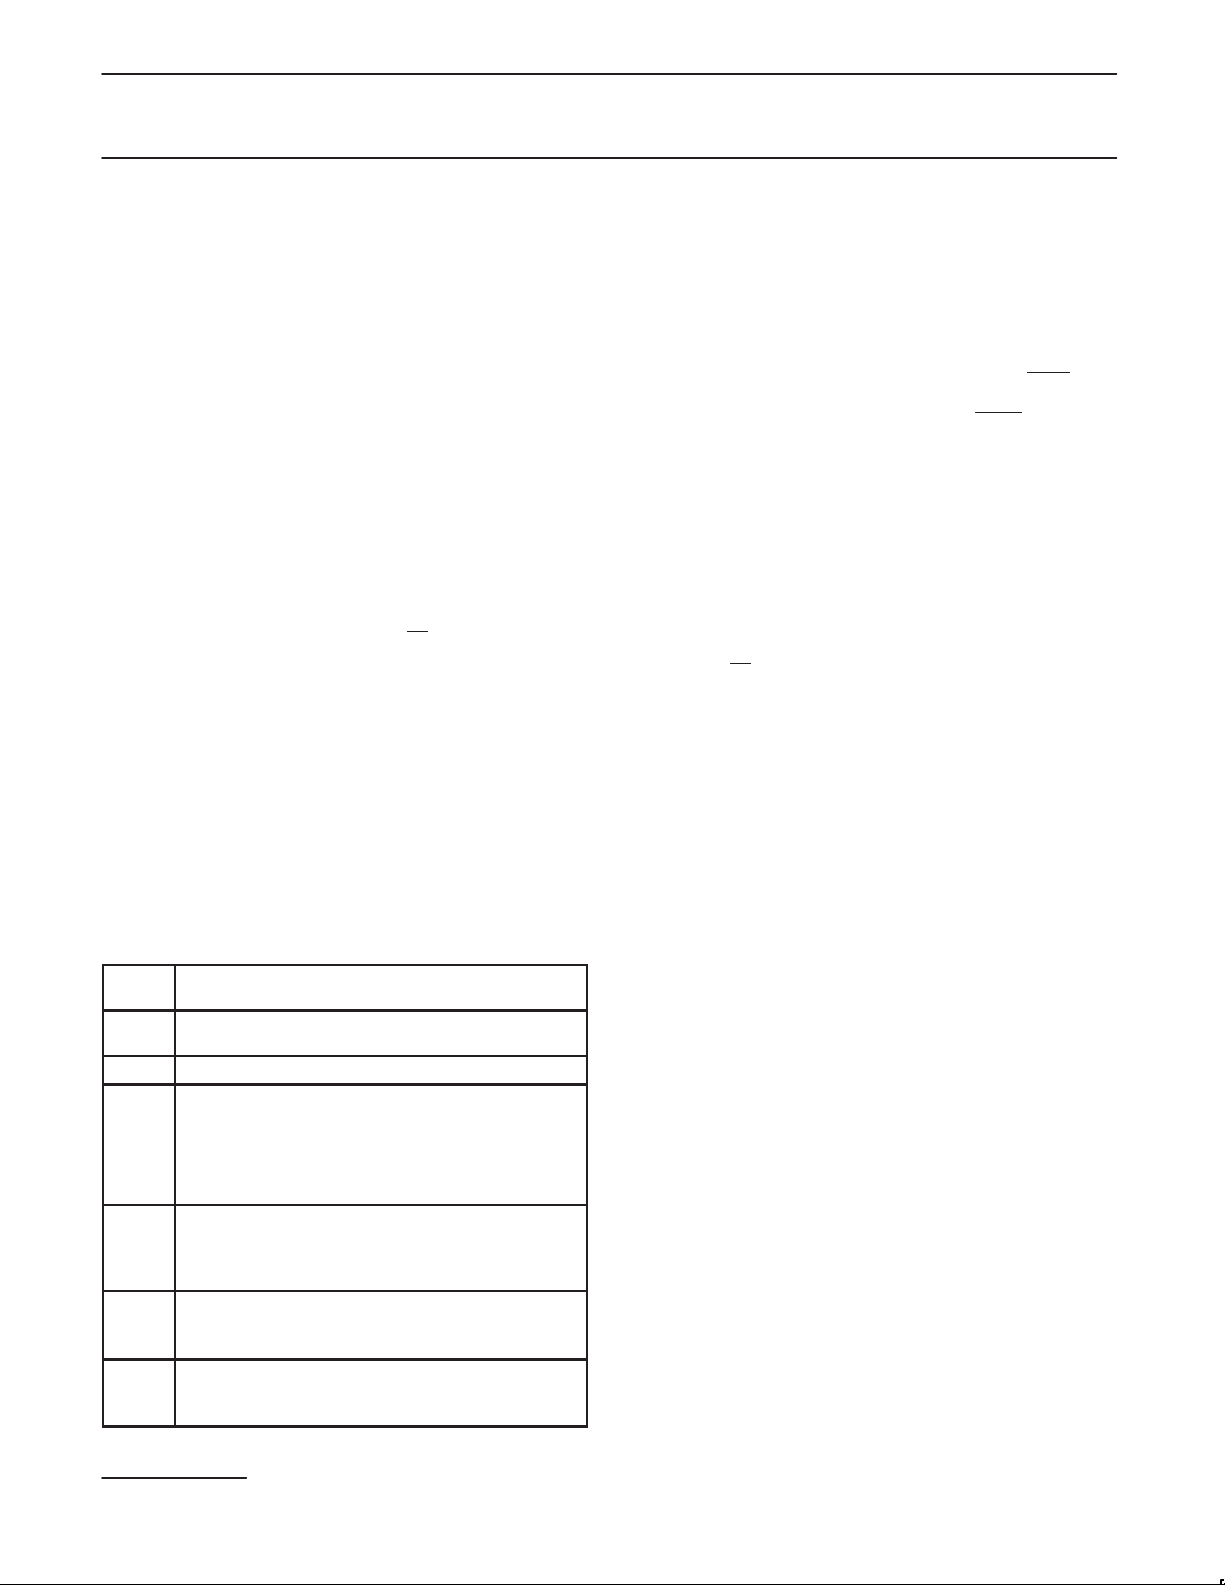
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
EPROM CHARACTERISTICS
To put the 87C576 in the parallel EPROM programming mode,
PSEN must be held high during power up, then driven low with reset
active. The 87C576 is programmed by using a modified Quick-Pulse
Programming algorithm.
The 87C576 contains two signature bytes that can be read and used
by an EPROM programming system to identify the device. The
signature bytes identify the device as an 87C576 manufactured by
Philips.
Table 3 shows the logic levels for reading the signature byte, and for
programming the program memory, the encryption table, and the
security bits. The circuit configuration and waveforms for quick-pulse
programming are shown in Figures 38 and 39. Figure 40 shows the
circuit configuration for normal program memory verification.
On-Board Programming (OBP)
The On-Board Programming facility consists of a series of internal
hardware resources coupled with internal firmware to facilitate
remote programming of the 87C576 through the serial port.
The OBP function is invoked by having the EA
voltage level at the time that the part exits reset. The OBP function
only requires that the TxD, RxD, V
connected to an external circuit in order to use this feature.
The OBP feature provides for the use of a wide range of baud rates
independent of the oscillator frequency used. It is also adaptable to
a wide range of oscillator frequencies. The OBP facility provides for
both auto-echo and no-echo of received characters. The OBP
feature requires that an initial character, an uppercase U, be sent to
the 87C576 to establish the baud rate to be used.
Once baud rate initialization has been performed, the OBP facility
only accepts Intel Hex records. The record-type field of these hex
records are used to indicate either commands or data for the OBP
facility. The maximum number of data bytes in a record is limited to
16 (decimal). These commands/data are summarized below:
Record
Type
00 Data record, programs the part with data indicated in
01 EOF record, no operation
02 Specify timing parameters
03 Program security bits
04 Display contents of USER EPROM array
05 Verify security bit status
Command/Data
Function
record starting with load address in the record
– rec length = 3 bytes
– load address = 0000
– 1st byte = timer count for 50µs programming pulse
– 2nd byte = timer count for 10µs delay between pulses
– 3rd byte = 0AH
– rec length = 1 byte
– load address = 0000
– 1st byte = sec bit values (xxxx xxB2B1)
– rec length = 00
– load address = 0000
– rec length = 00
– load address = 0000
, VCC, and VPP pins be
SS
/VPP pin at the V
PP
Quick-Pulse Programming (Parallel)
The setup for microcontroller quick-pulse programming is shown in
Figure 38. Note that the 87C576 is running with a 4 to 6MHz
oscillator. The reason the oscillator needs to be running is that the
device is executing internal address and program data transfers.
The address of the EPROM location to be programmed is applied to
ports 3 and 2, as shown in Figure 38. The code byte to be
programmed into that location is applied to port 0. RST, PSEN
pins of ports 2 and 1 specified in Table 3 are held at the ‘Program
Code Data’ levels indicated in Table 3. The ALE/PROG
low 25 times as shown in Figure 39.
To program the encryption table, repeat the 25 pulse programming
sequence for addresses 0 through 1FH, using the ‘Pgm Encryption
Table’ levels. Do not forget that after the encryption table is
programmed, verification cycles will produce only encrypted data.
To program the security bits, repeat the 25 pulse programming
sequence using the ‘Pgm Security Bit’ levels. After one security bit is
programmed, further programming of the code memory and
encryption table is disabled. However, the other security bit can still
be programmed.
Note that the EA
maximum specified V
glitch above that voltage can cause permanent damage to the
device. The V
and overshoot.
/VPP pin must not be allowed to go above the
level for any amount of time. Even a narrow
PP
source should be well regulated and free of glitches
PP
and
is pulsed
Program V erification
If security bit 2 has not been programmed, the on-chip program
memory can be read out for program verification. The address of the
program memory locations to be read is applied to ports 3 and 2 as
shown in Figure 40. The other pins are held at the ‘Verify Code Data’
levels indicated in Table 3. The contents of the address location will
be emitted on port 0. External pull-ups are required on port 0 for this
operation.
If the encryption table has been programmed, the data presented at
port 0 will be the exclusive NOR of the program byte with one of the
encryption bytes. The user will have to know the encryption table
contents in order to correctly decode the verification data. The
encryption table itself cannot be read out.
Reading the Signature Bytes
The signature bytes are read by the same procedure as a normal
verification of locations 030H and 031H, except that P1.0 and P1.1
need to be pulled to a logic low. The values are:
(030H) = 15H indicates manufactured by Philips
(B6H) = B6H indicates 87C576
Program/Verify Algorithms
Any algorithm in agreement with the conditions listed in Table 3, and
which satisfies the timing specifications, is suitable.
Trademark phrase of Intel Corporation.
1998 Jun 04
39
Page 40
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
Table 3. EPROM Programming Modes
MODE RST PSEN ALE/PROG EA/V
Read signature 0 0 1 1 0 0 0 0
Program code data 0 0 0* V
Verify code data 0 0 1 1 0 0 1 1
Pgm encryption table 0 0 0* V
Pgm security bit 1 0 0 0* V
Pgm security bit 2 0 0 0* V
NOTES:
1. ‘0’ = Valid low for that pin, ‘1’ = valid high for that pin.
= 12.75V ±0.25V.
2. V
PP
= 5V±10% during programming and verification.
3. V
CC
* ALE/PROG
minimum of 10µs.
receives 5 programming pulses while VPP is held at 12.75V . Each programming pulse is low for 50µs (±10µs) and high for a
PP
PP
PP
PP
PP
P2.7 P2.6 P1.1 P1.0
1 0 1 1
1 0 1 0
1 1 1 1
1 1 0 0
83C576/87C576
1998 Jun 04
40
Page 41
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
83C576/87C576
ALE/PROG:
ALE/PROG:
1
0
4–6MHz
+5V
PGM DATA
+12.75V
5 50µs PULSES TO GROUND
0
1
0
A8–A12
SU00257B
A0–A7
+5V
AV
CC
P3
0
1
1
RST
P1.0
P1.1
XTAL2
XTAL1
AV
SS
V
SS
87C576
V
CC
/V
EA
PP
ALE/PROG
PSEN
P2.7
P2.6
P2.0–P2.4
P0
Figure 38. Programming Configuration
5 PULSES
1
0
50µs+1010µs MIN
4–6MHz
A0–A7
SU00664
Figure 39. PROG Waveform
+5V
AV
CC
P3
0
1
1
RST
P1.0
P1.1
XTAL2
XTAL1
AV
SS
V
SS
87C576
EA
ALE/PROG
PSEN
P2.0–P2.4
/V
V
PP
P2.7
P2.6
+5V
CC
P0
PGM DATA
1
1
0
0 ENABLE
0
A8–A12
SU00258B
Figure 40. Program Verification
1998 Jun 04
41
Page 42
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
EPROM PROGRAMMING AND VERIFICATION CHARACTERISTICS
T
= 21°C to +27°C, VCC = 5V±10%, VSS = 0V (See Figure 41)
amb
SYMBOL
V
PP
I
PP
1/t
CLCL
t
AVGL
t
GHAX
t
DVGL
t
GHDX
t
EHSH
t
SHGL
t
GHSL
t
GLGH
t
AVQV
t
ELQZ
t
EHQZ
t
GHGL
Programming supply voltage 12.5 13.0 V
Programming supply current 50 mA
Oscillator frequency 4 12 MHz
Address setup to PROG low 48t
Address hold after PROG 48t
Data setup to PROG low 48t
Data hold after PROG 48t
P2.7 (ENABLE) high to V
VPP setup to PROG low 10 µs
VPP hold after PROG 10 µs
PROG width 40 60 µs
Address to data valid 48t
ENABLE low to data valid 48t
Data float after ENABLE 0 48t
PROG high to PROG low 10 µs
PARAMETER MIN MAX UNIT
PP
48t
CLCL
CLCL
CLCL
CLCL
CLCL
83C576/87C576
CLCL
CLCL
CLCL
PROGRAMMING* VERIFICATION*
P3.0–P3.7
P2.0–P2.4
PORT 0
t
DVGL
ALE/PROG
EA/V
PP
P2.7
ENABLE
* FOR PROGRAMMING VERIFICATION SEE FIGURE 38.
FOR VERIFICATION CONDITIONS SEE FIGURE 40.
t
EHSH
t
t
SHGL
t
AVGL
GLGH
ADDRESS ADDRESS
t
AVQV
DATA IN DATA OUT
t
t
GHAX
t
GHGL
t
GHSL
LOGIC 0
GHDX
LOGIC 1 LOGIC 1
t
ELQV
Figure 41. EPROM Programming and Verification
t
EHQZ
SU00207
1998 Jun 04
42
Page 43
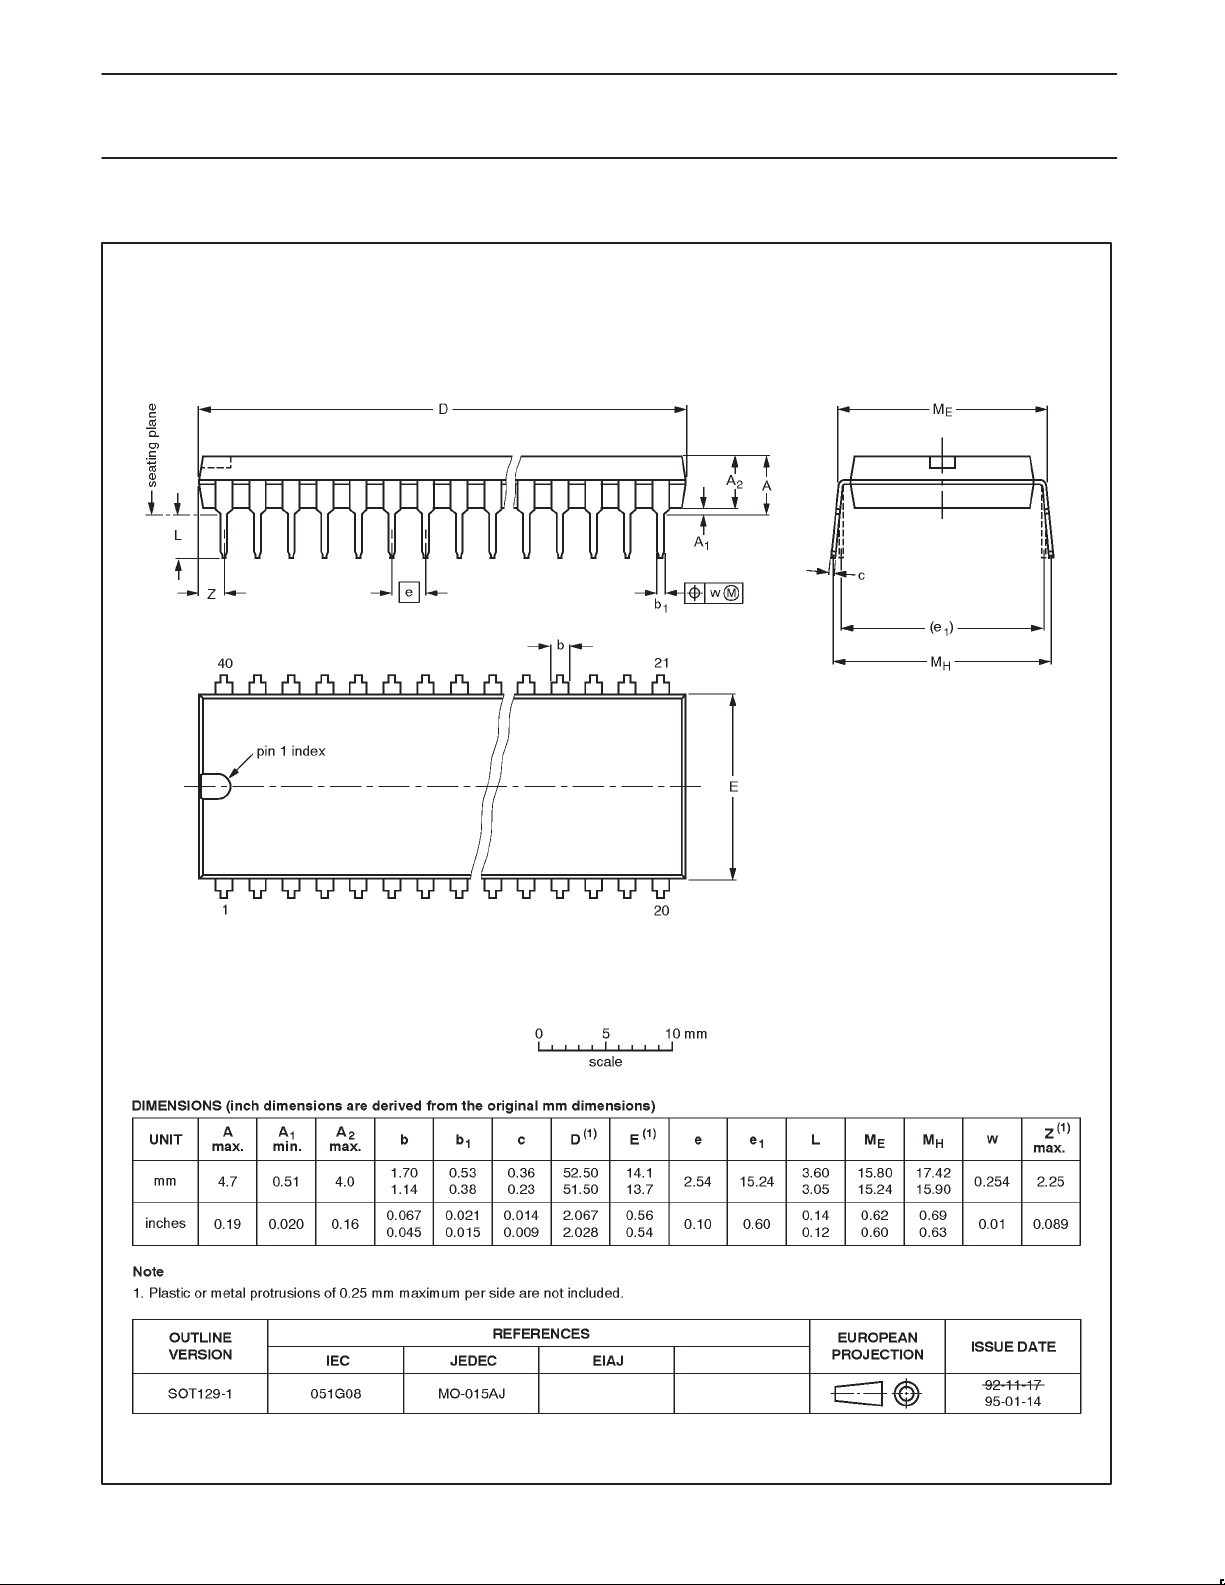
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
DIP40: plastic dual in-line package; 40 leads (600 mil) SOT129-1
83C576/87C576
1998 Jun 04
43
Page 44
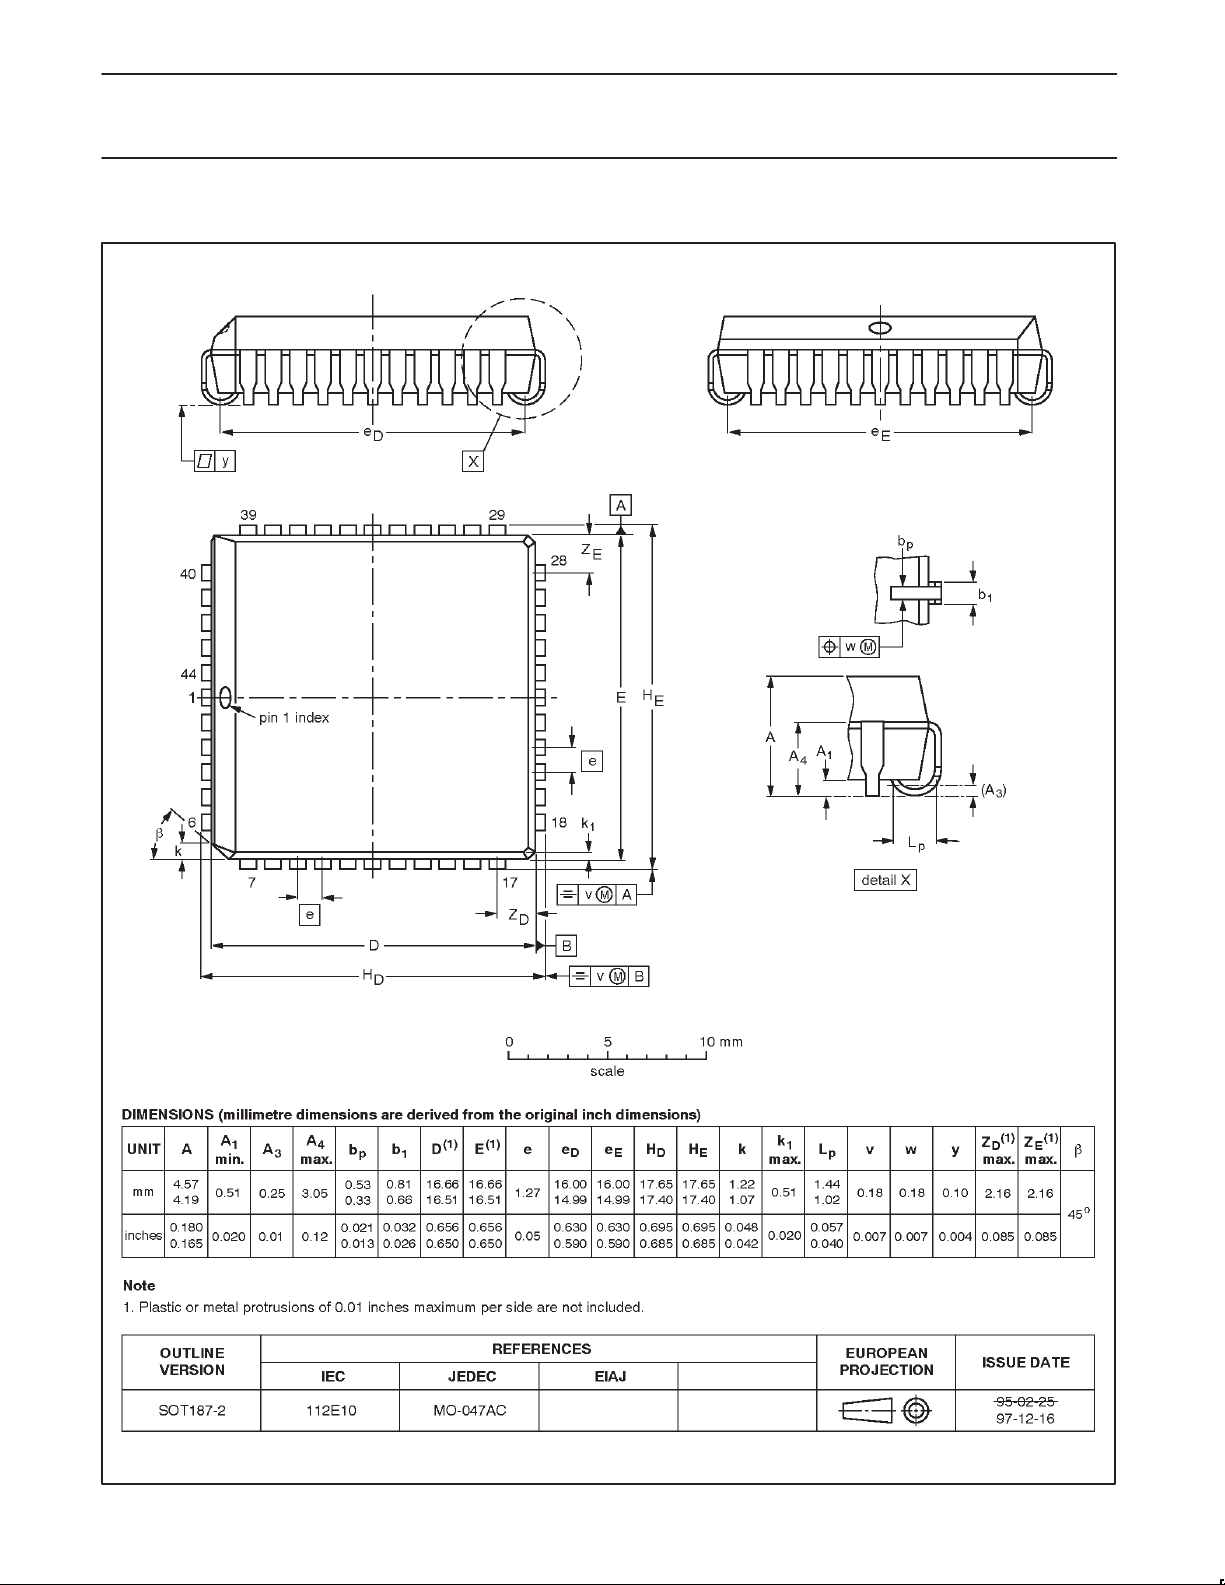
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
PLCC44: plastic leaded chip carrier; 44 leads SOT187-2
83C576/87C576
1998 Jun 04
44
Page 45
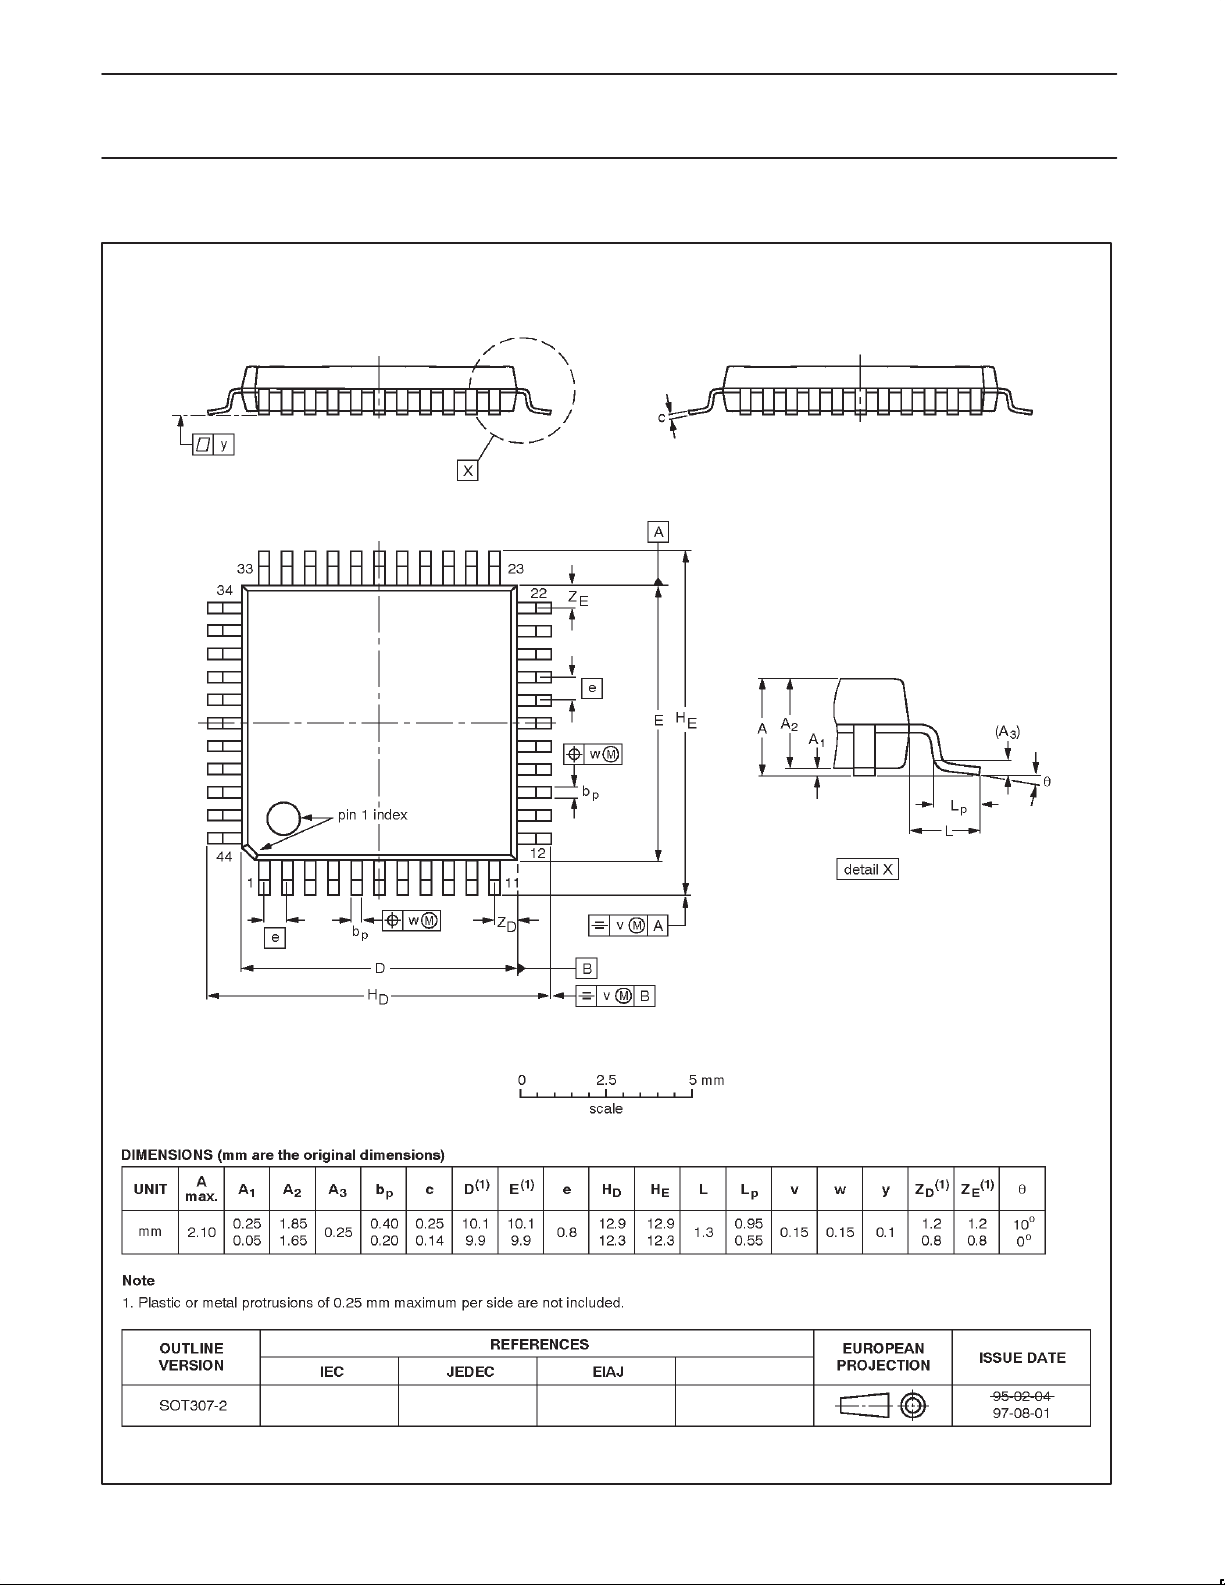
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
QFP44: plastic quad flat package; 44 leads (lead length 1.3 mm); body 10 x 10 x 1.75 mm SOT307-2
83C576/87C576
1998 Jun 04
45
Page 46
Philips Semiconductors Product specification
80C51 8-bit microcontroller family
8K/256 OTP/ROM, 6 channel 10-bit A/D, 4 comparators,
failure detect circuitry, watchdog timer
Data sheet status
Data sheet
status
Objective
specification
Preliminary
specification
Product
specification
Product
status
Development
Qualification
Production
Definition
This data sheet contains the design target or goal specifications for product development.
Specification may change in any manner without notice.
This data sheet contains preliminary data, and supplementary data will be published at a later date.
Philips Semiconductors reserves the right to make chages at any time without notice in order to
improve design and supply the best possible product.
This data sheet contains final specifications. Philips Semiconductors reserves the right to make
changes at any time without notice in order to improve design and supply the best possible product.
[1]
83C576/87C576
[1] Please consult the most recently issued datasheet before initiating or completing a design.
Definitions
Short-form specification — The data in a short-form specification is extracted from a full data sheet with the same type number and title. For
detailed information see the relevant data sheet or data handbook.
Limiting values definition — Limiting values given are in accordance with the Absolute Maximum Rating System (IEC 134). Stress above one
or more of the limiting values may cause permanent damage to the device. These are stress ratings only and operation of the device at these or
at any other conditions above those given in the Characteristics sections of the specification is not implied. Exposure to limiting values for extended
periods may affect device reliability.
Application information — Applications that are described herein for any of these products are for illustrative purposes only. Philips
Semiconductors make no representation or warranty that such applications will be suitable for the specified use without further testing or
modification.
Disclaimers
Life support — These products are not designed for use in life support appliances, devices or systems where malfunction of these products can
reasonably be expected to result in personal injury . Philips Semiconductors customers using or selling these products for use in such applications
do so at their own risk and agree to fully indemnify Philips Semiconductors for any damages resulting from such application.
Right to make changes — Philips Semiconductors reserves the right to make changes, without notice, in the products, including circuits, standard
cells, and/or software, described or contained herein in order to improve design and/or performance. Philips Semiconductors assumes no
responsibility or liability for the use of any of these products, conveys no license or title under any patent, copyright, or mask work right to these
products, and makes no representations or warranties that these products are free from patent, copyright, or mask work right infringement, unless
otherwise specified.
Philips Semiconductors
811 East Arques Avenue
P.O. Box 3409
Sunnyvale, California 94088–3409
Telephone 800-234-7381
Copyright Philips Electronics North America Corporation 1998
All rights reserved. Printed in U.S.A.
Date of release: 06-98
Document order number: 9397 750 04024
1998 Jun 04
46
 Loading...