

Page 1
Am29F200B
2 Megabit (256 K x 8-Bit/128 K x 16-Bit)
CMOS 5.0 Volt-only, Boot Sector Flash Memory
DISTINCTIVE CHARACTERISTICS
■ 5.0 V ± 10% for read and write operations
— Minimizes system level power requirements
■ Manufactured on 0.32 µm process technology
— Compatible with 0.5 µm Am29F200A device
■ High performance
— Access times as fast as 45 ns
■ Low power consumption
— 20 mA typical active read current (byte mode)
— 28 mA typical active read current for
(word mode)
— 30 mA typical program/erase current
—1 µA typical standby current
■ Sector erase architecture
— One 16 Kbyte, two 8 Kbyte, one 32 Kbyte , and
three 64 Kbyte sectors (byte mode)
— One 8 Kword, two 4 Kword, one 16 Kword, and
three 32 Kword sectors (word mode)
— Supports full chip erase
— Sector Protection features:
A hardware method of locking a sector to
prevent any program or erase operations within
that sector
Sectors can be loc ked vi a progr amming equipm ent
T emporary Sector Unprotect feat ure allows code
changes in previously locked sectors
■ T op or bot tom boot bloc k configura tions av ailabl e
■ Embedded Algorithms
— Embedded Erase algorithm automatically
preprograms and erases the entire chip or any
combination of designated sectors
— Embedded Program algorithm automatically
writes and verifies data at specified addresses
■ Minimum 1,000,000 write/erase cycles guaranteed
■ 20-year data retention at 125°C
— Reliable operation for the life of the system
■ Package options
— 44-pin SO
— 48-pin TSOP
— Known Good Die (KGD)
(see publication number 21257)
■ Compatible with JEDEC standards
— Pinout and software compatible with
single-power-supply flash
— Superior inadvertent write protection
■ Data# Polling and Toggle Bit
— Detects program or erase cycle completion
■ Ready/Busy# output (RY/BY#)
— Hardware method for detection of program or
erase cycle completion
■ Erase Suspend/Erase Resume
— Supports reading data from a sector not
being erased
■ Hardware RESET# pin
— Resets internal state machine to the reading
array data
This Data Sheet states AMD’s current technical specifications regarding the Products described herein. This Data
Sheet may be revised by subsequent versions or modifications due to changes in technical specifications.
Publication# 21526 Rev: B Amendment/+2
Issue Date: July 2, 1999
Page 2
GENERAL DESCRIPTION
The Am29F200B is a 2 Mbit, 5.0 Volt-only Flash
memory organized as 262,144 bytes or 131,072 words .
The 8 bits of data appear on DQ0–DQ7; the 16 bits on
DQ0–DQ15. The Am29F200B is offered in 44-pin SO
and 48-pin TSOP packages. The device is also available in Known Good Die (KGD) form. For more
information, refer to publication number 21257. This
device is designed to be programmed in-system with
the standard system 5.0 volt V
is not required for program or erase operations.
V
PP
The device can also be reprogrammed in standard
EPROM programmers.
This device is manufactured using AMD’s 0.32 µm
process technology, and offers all the features and
benefits of the Am29F200A, which was manufactured
using 0.5 µm process technology.
The standard device offers access times of 45, 50, 55,
70, 90, and 120 ns, allowing op eration of high-speed
microprocessors without wait states. To eliminate bus
contention the device has separate chip enable (CE#),
write enable (WE#) and output enable (OE#) controls.
The device requires only a single 5.0 volt power
supply for both read and write functions. Internally
generated and regulated voltages are provided for the
program and erase operations.
The device is entirely command set compatible with the
JEDEC single-power-supply Flash standard. Commands are written to the command regis ter using
standard micropr ocessor wri te timings. Register co ntents serve as input to an internal state-machine that
controls the erase and programming circuitry. Write
cycles also internally latch addresses and data needed
for the programming and erase operations. Reading
data out of the device is similar to reading from other
Flash or EPROM devices.
Device programming occurs by executing the program
command sequence. This initiates the Embedded
Program algorithm—an internal algorithm that automatically times the program pulse widths and verifies
proper cell margin.
supply. A 12.0 volt
CC
Device erasure occurs by executing the erase
command sequence. This initiates the Embedded
Erase algorithm—an internal algorithm that automatically preprograms the array (if it is not already
programmed) before executing the erase operation.
During erase, the device automatically times the erase
pulse widths and verifies proper cell margin.
The host system can detect whether a program or
erase operation is complete by observing the RY/BY#
pin, or by reading the DQ7 (Data# Polling) and DQ6/
DQ2 (toggle) status bits. After a program or e rase
cycle has been completed, the device is ready to read
array data or accept another command.
The sector erase archite cture allo ws m emory sect ors
to be erased and reprogrammed without affecting the
data contents of other sectors. The device is fully
erased when shipped from the factory.
Hardware data protection measures include a low
detector that automatically in hibits write opera-
V
CC
tions during power transitions. The hardware sector
protection feature disables both program and erase
operations in an y combi nati on of t he sec tors o f memory.
This can be achieved via programming equipment.
The Erase Suspend feature enables the user to put
erase on hold for any period of time to read data from,
or program data to, any sector that is not selected for
erasure. True bac kg round er ase can thus be achieved.
The hardware RESET# pi n terminates any operation
in progress and resets the internal state machine to
reading array dat a. The RESET# pin ma y be tied to the
system reset circuitry. A system reset would thus also
reset the device, enabling the system microprocessor
to read the boot-up firmware from the Flash memory.
The system can place the device into the standby
mode. Po wer consumpt ion is grea tly reduc ed in this mode .
AMD’s Flash technology combines years of Flash
memory manufacturing experience to produce the
highest levels of quality, reliability and cost effectiveness. The device electrically erases all bi ts within a
sector simultaneously via Fowler-Nordheim tunneling.
The data is programmed using hot electron injection.
2 Am29F200B
Page 3
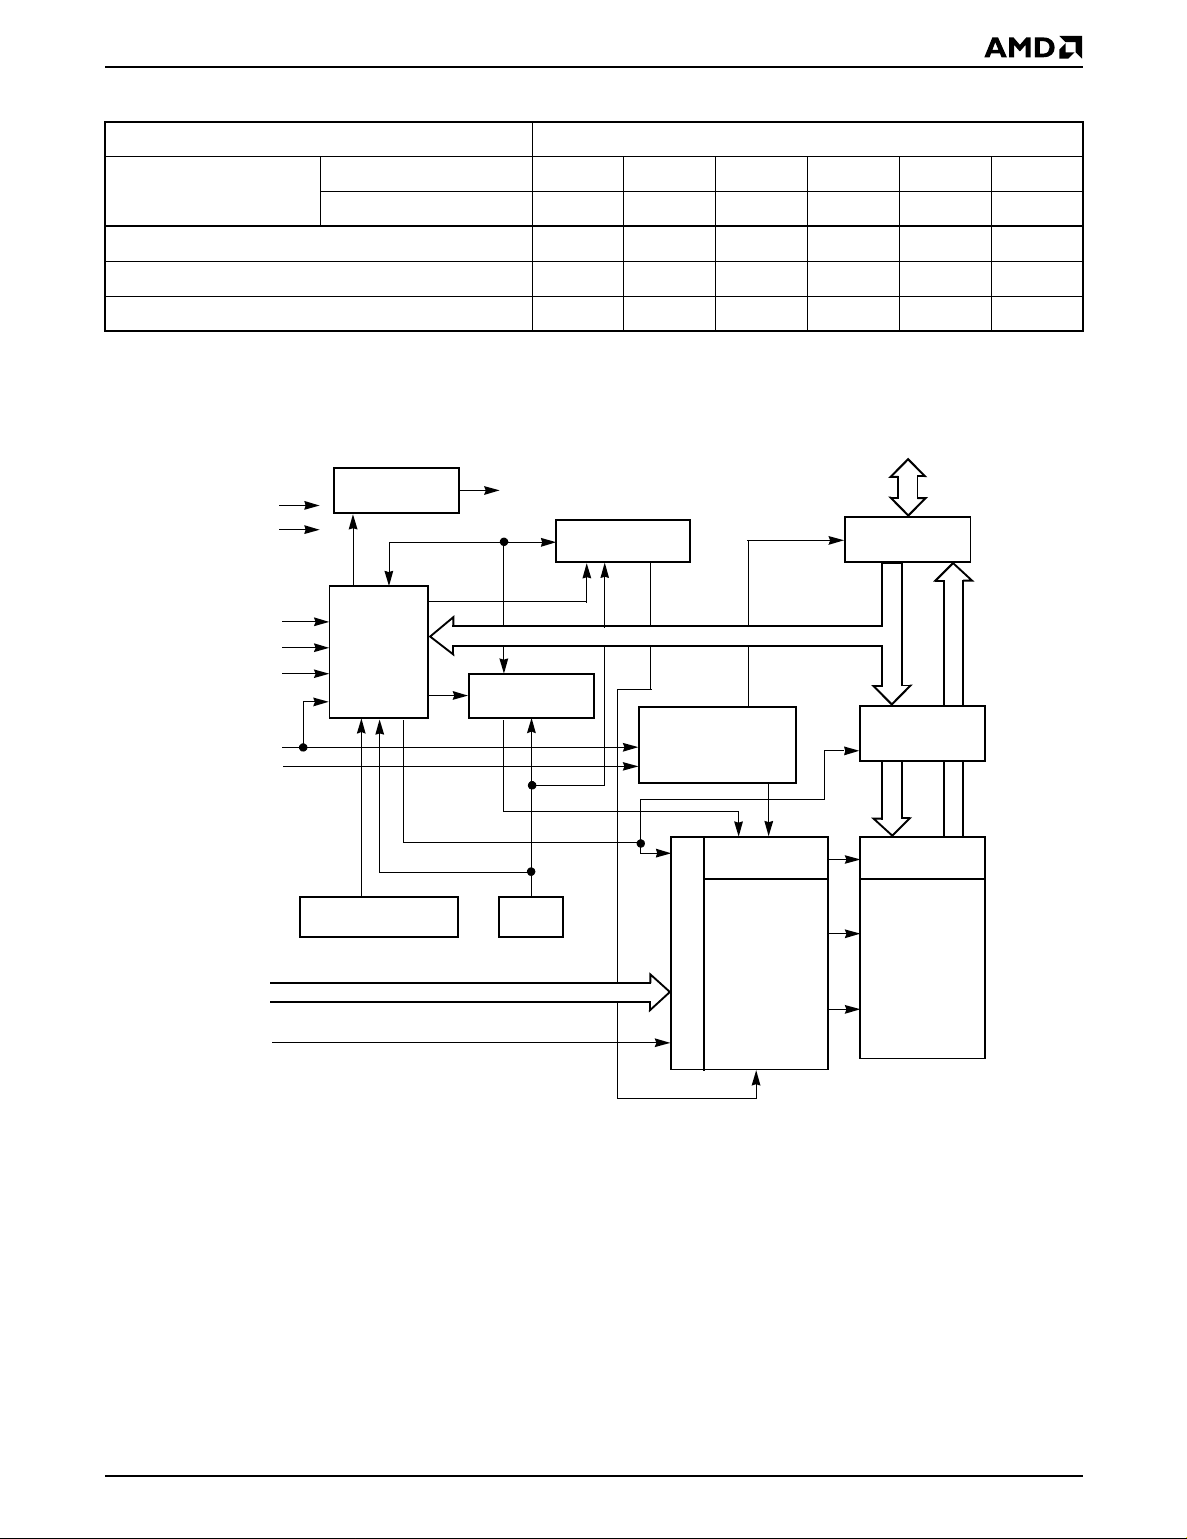
PRODUCT SELECTOR GUIDE
Family Part Number Am29F200B
= 5.0 V ± 5% -45 -50
V
Speed Option
Max access time, ns (t
Max CE# access time, ns (t
Max OE# access time, ns (t
CC
= 5.0 V ± 10% -55 -70 -90 -120
V
CC
) 4550557090120
ACC
) 4550557090120
CE
) 303030303550
OE
BLOCK DIAGRAM
DQ0–DQ15
V
CC
V
SS
WE#
BYTE#
RESET#
CE#
OE#
A0–A16
A-1
RY/BY#
Buffer
State
Control
Command
Register
V
Detector
CC
RY/BY#
PGM Voltage
Generator
Timer
Erase Voltage
Generator
STB
Chip Enable
Output Enable
Logic
Y-Decoder
Address Latch
STB
Input/Output
Buffers
Data
Latch
Y-Gating
Cell MatrixX-Decoder
21526B-1
Am29F200B 3
Page 4
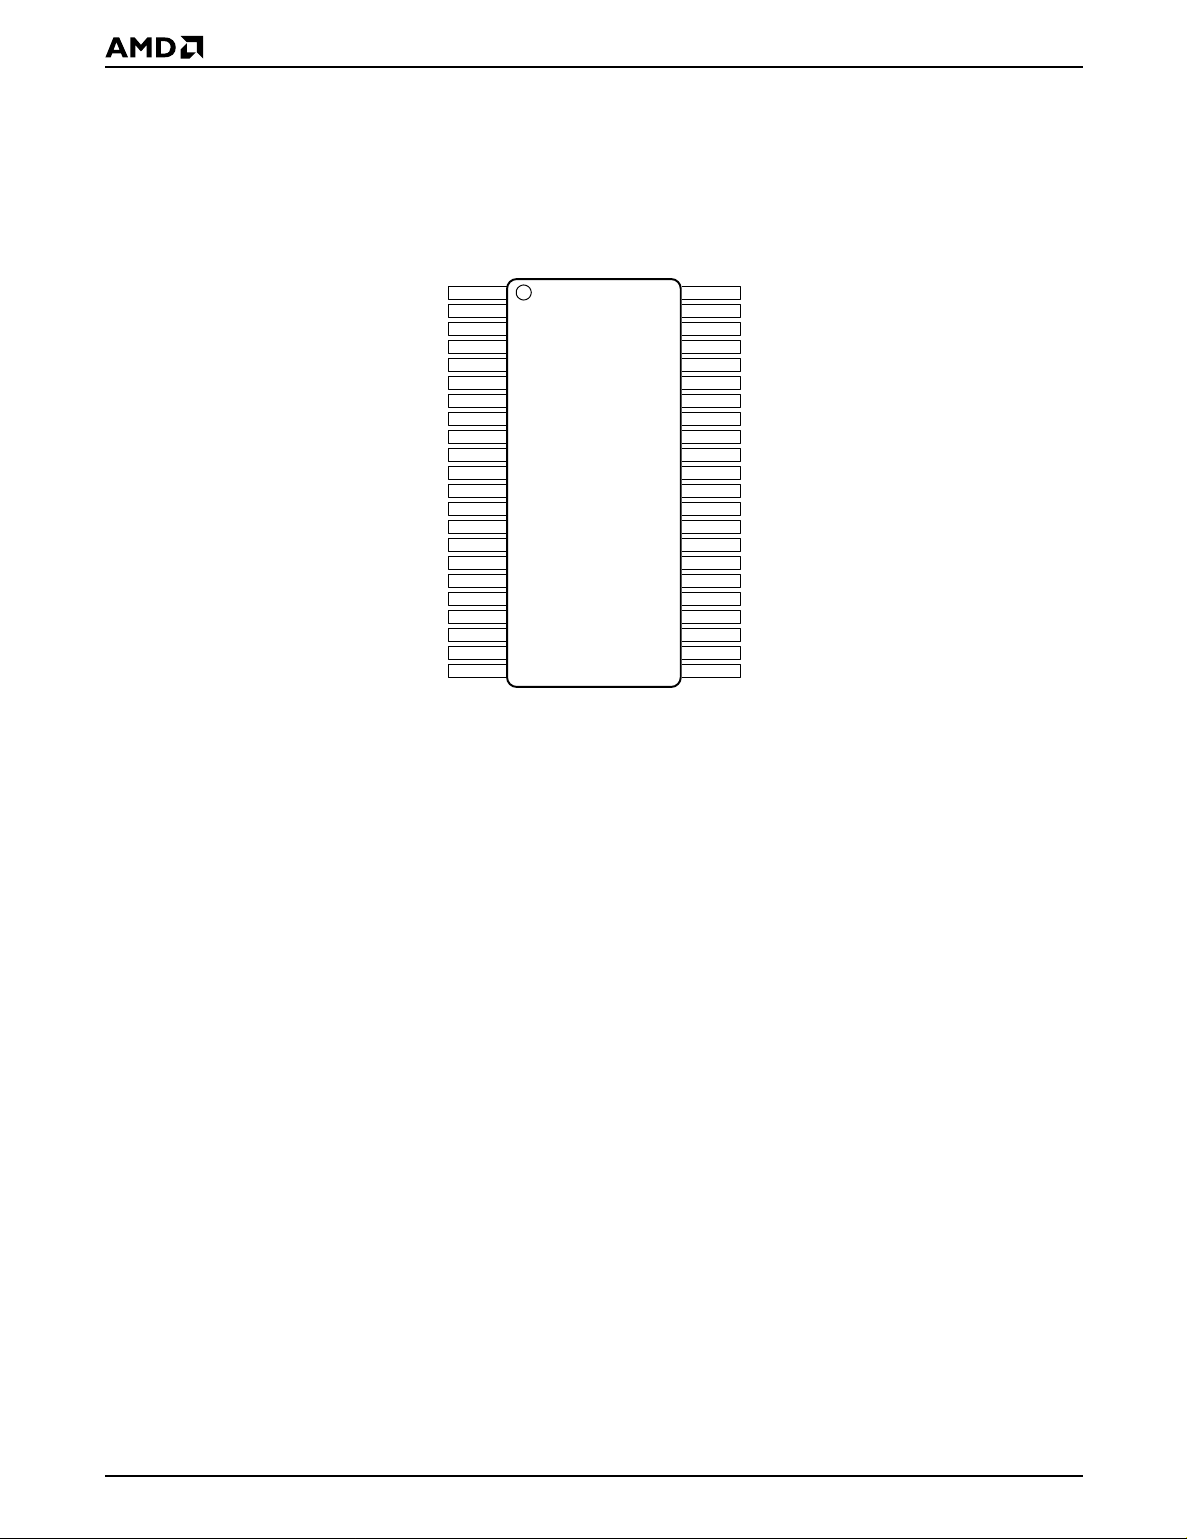
CONNECTION DIAGRAMS
This device is also available in Known Good Die (KGD) form. Refer to publication number 21257 for
more information.
NC
RY/BY#
NC
A7
A6
A5
A4
A3
A2
A1
A0
CE#
V
OE#
DQ0
DQ8
DQ1
DQ9
DQ2
DQ10
DQ3
DQ11
SS
10
11
12
13
14
15
16
17
18
19
20
21
22
1
2
3
4
5
6
7
8
9
SO
44
43
42
41
40
39
38
37
36
35
34
33
32
31
30
29
28
27
26
25
24
23
RESET#
WE#
A8
A9
A10
A11
A12
A13
A14
A15
A16
BYTE#
V
SS
DQ15/A-1
DQ7
DQ14
DQ6
DQ13
DQ5
DQ12
DQ4
V
CC
21526B-2
4 Am29F200B
Page 5
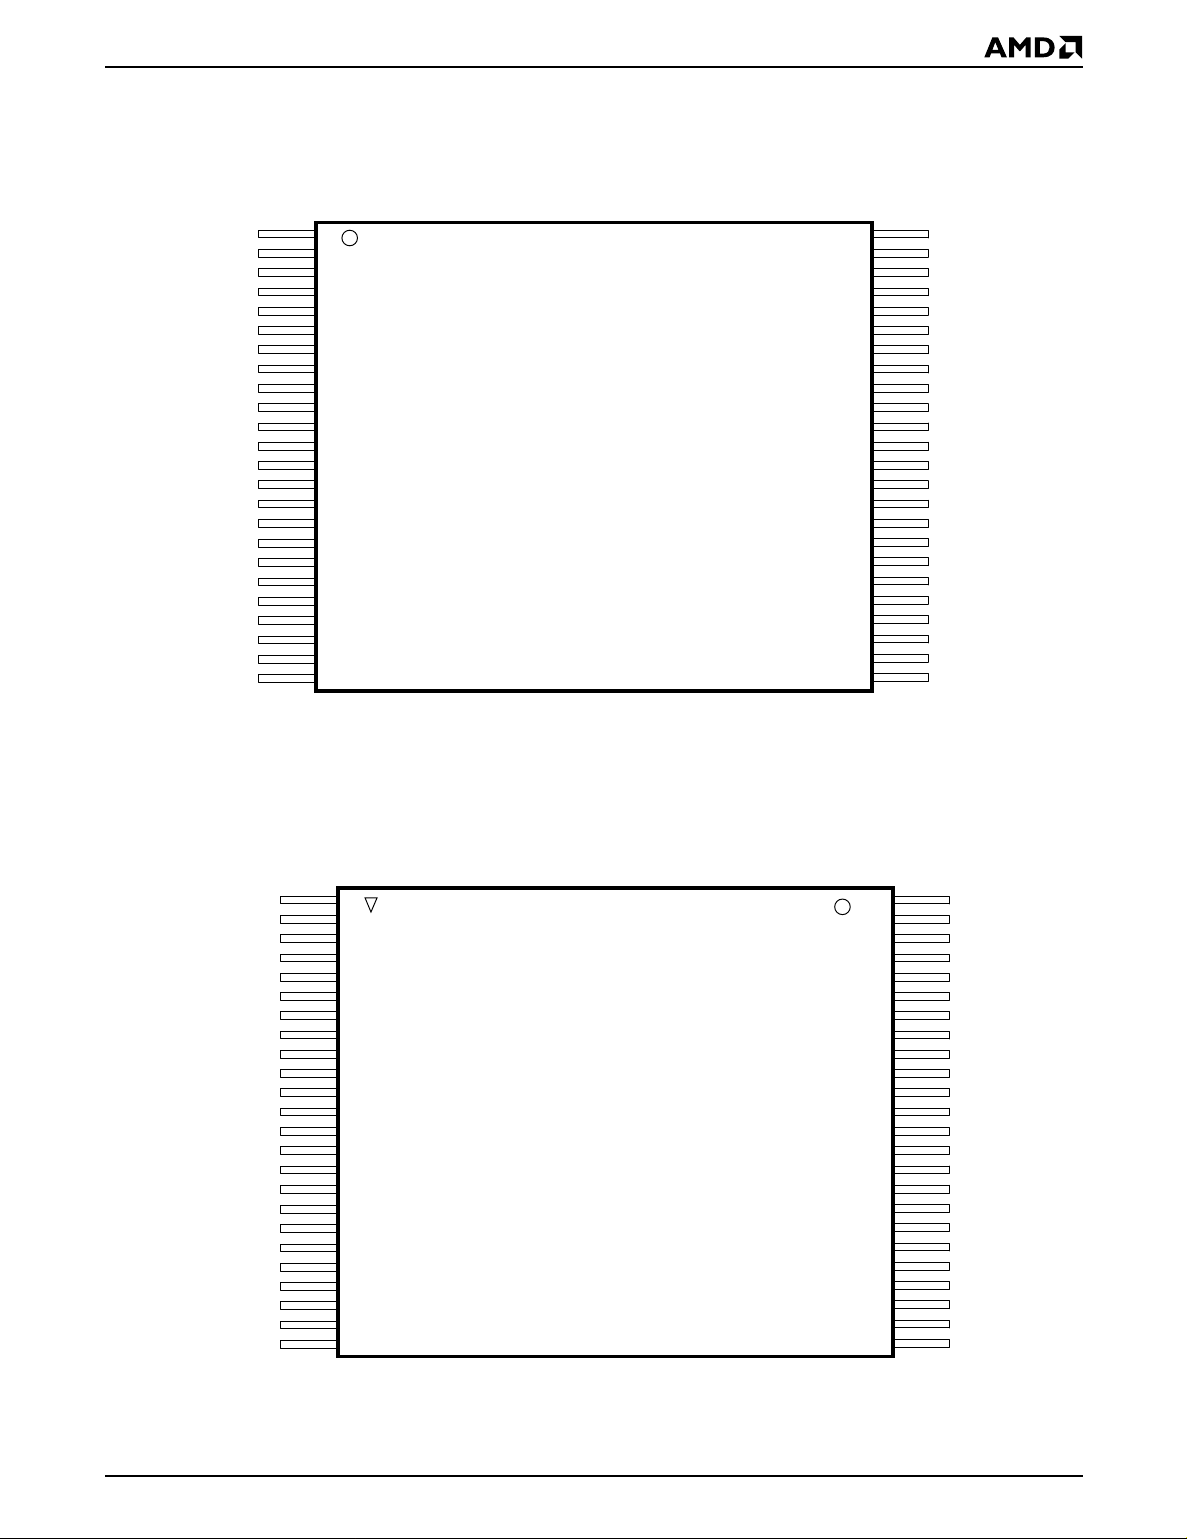
CONNECTION DIAGRAMS
This device is also available in Known Good Die (KGD) form. Refer to publication number 21257 for
more information.
A15
A14
A13
A12
A11
A10
A9
A8
NC
NC
WE#
RESET#
NC
NC
RY/BY#
NC
NC
A7
A6
A5
A4
A3
A2
A1
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
Standard TSOP
48
47
46
45
44
43
42
41
40
39
38
37
36
35
34
33
32
31
30
29
28
27
26
25
A16
BYTE#
V
SS
DQ15/A-1
DQ7
DQ14
DQ6
DQ13
DQ5
DQ12
DQ4
V
CC
DQ11
DQ3
DQ10
DQ2
DQ9
DQ1
DQ8
DQ0
OE#
V
SS
CE#
A0
21526B-3
A16
BYTE#
V
SS
DQ15/A-1
DQ7
DQ14
DQ6
DQ13
DQ5
DQ12
DQ4
V
CC
DQ11
DQ3
DQ10
DQ2
DQ9
DQ1
DQ8
DQ0
OE#
V
SS
CE#
A0
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
Reverse TSOP
48
47
46
45
44
43
42
41
40
39
38
37
36
35
34
33
32
31
30
29
28
27
26
25
A15
A14
A13
A12
A11
A10
A9
A8
NC
NC
WE#
RESET#
NC
NC
RY/BY#
NC
NC
A7
A6
A5
A4
A3
A2
A1
21526B-4
Am29F200B 5
Page 6
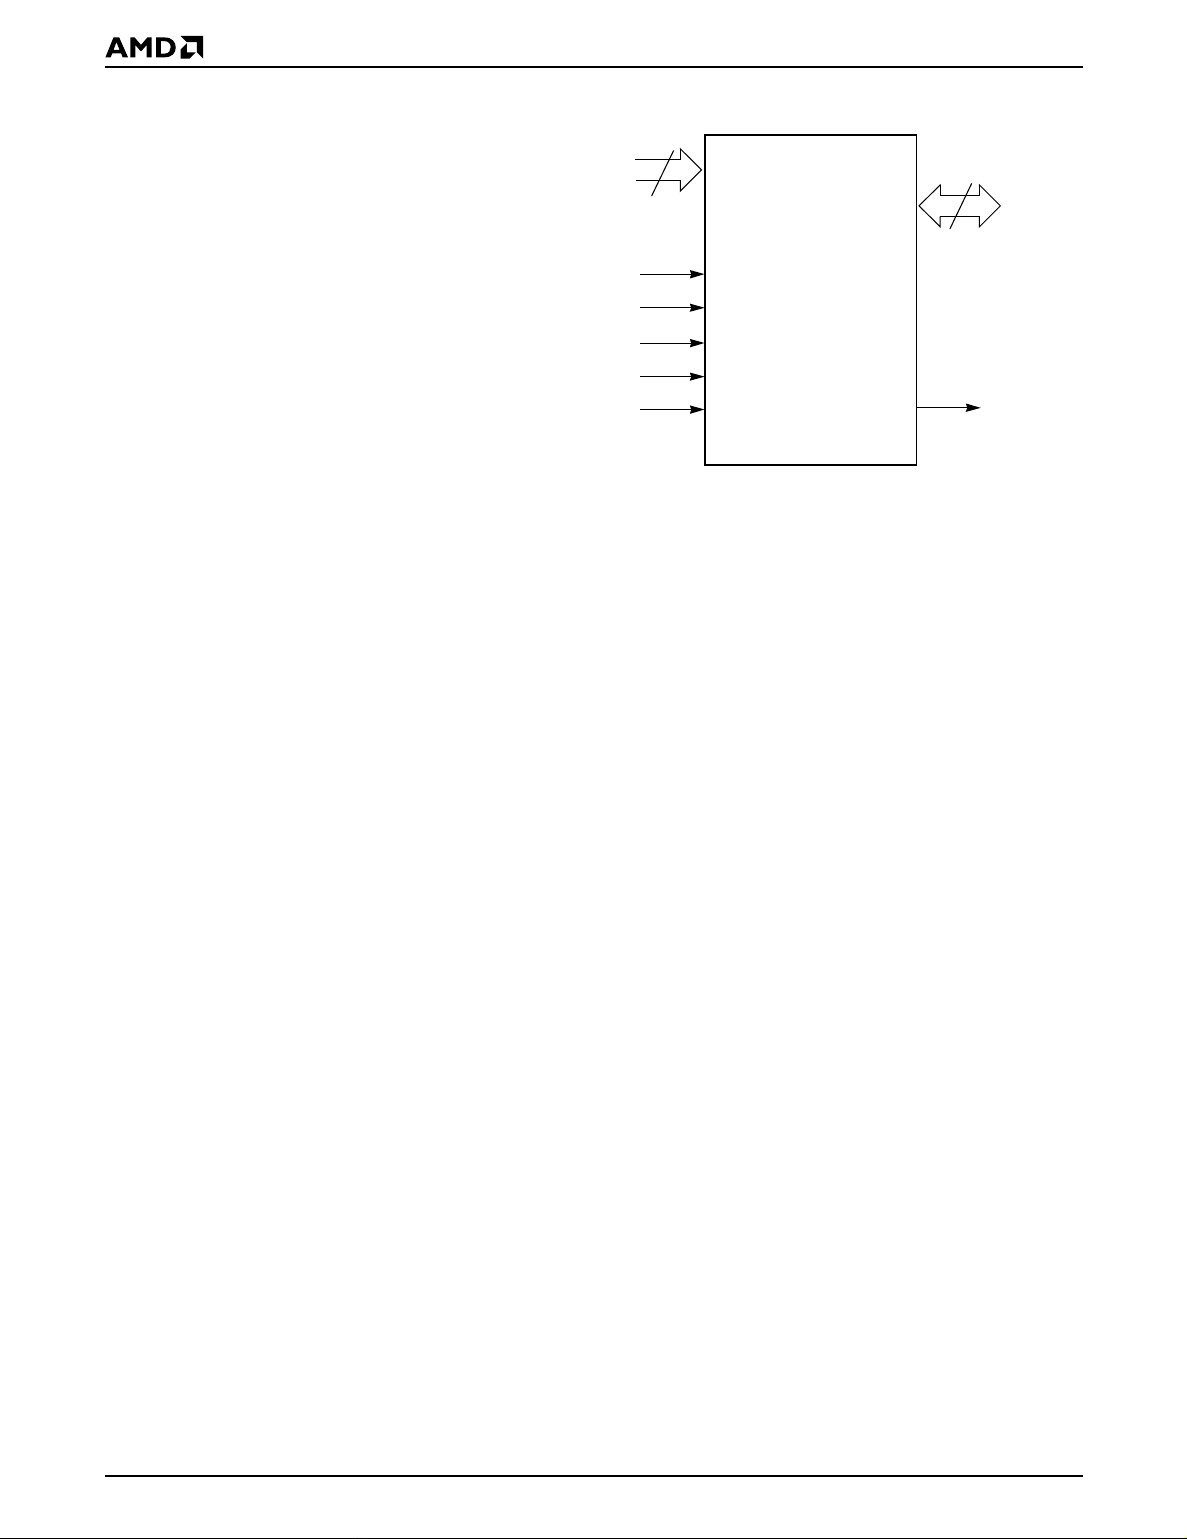
PIN CONFIGURATION
A0–A16 = 17 addresses
DQ0–DQ14 = 15 data inputs/outputs
DQ15/A-1 = DQ15 (data input/output, word mode),
A-1 (LSB address input, byte mode)
LOGIC SYMBOL
17
A0–A16
16 or 8
DQ0–DQ15
(A-1)
BYTE# = Selects 8-bit or 16-bit mode
CE# = Chip enable
OE# = Output enable
WE# = Write enable
RESET# = Hardware reset pin, active low
RY/BY# = Ready/Busy output
= +5.0 V single power supply
V
CC
(see Product Selector Guide for
device speed ratings and voltage
supply tolerances)
V
SS
= Device ground
NC = Pin not connected internally
CE#
OE#
WE#
RESET#
BYTE# RY/BY#
21526B-5
6 Am29F200B
Page 7
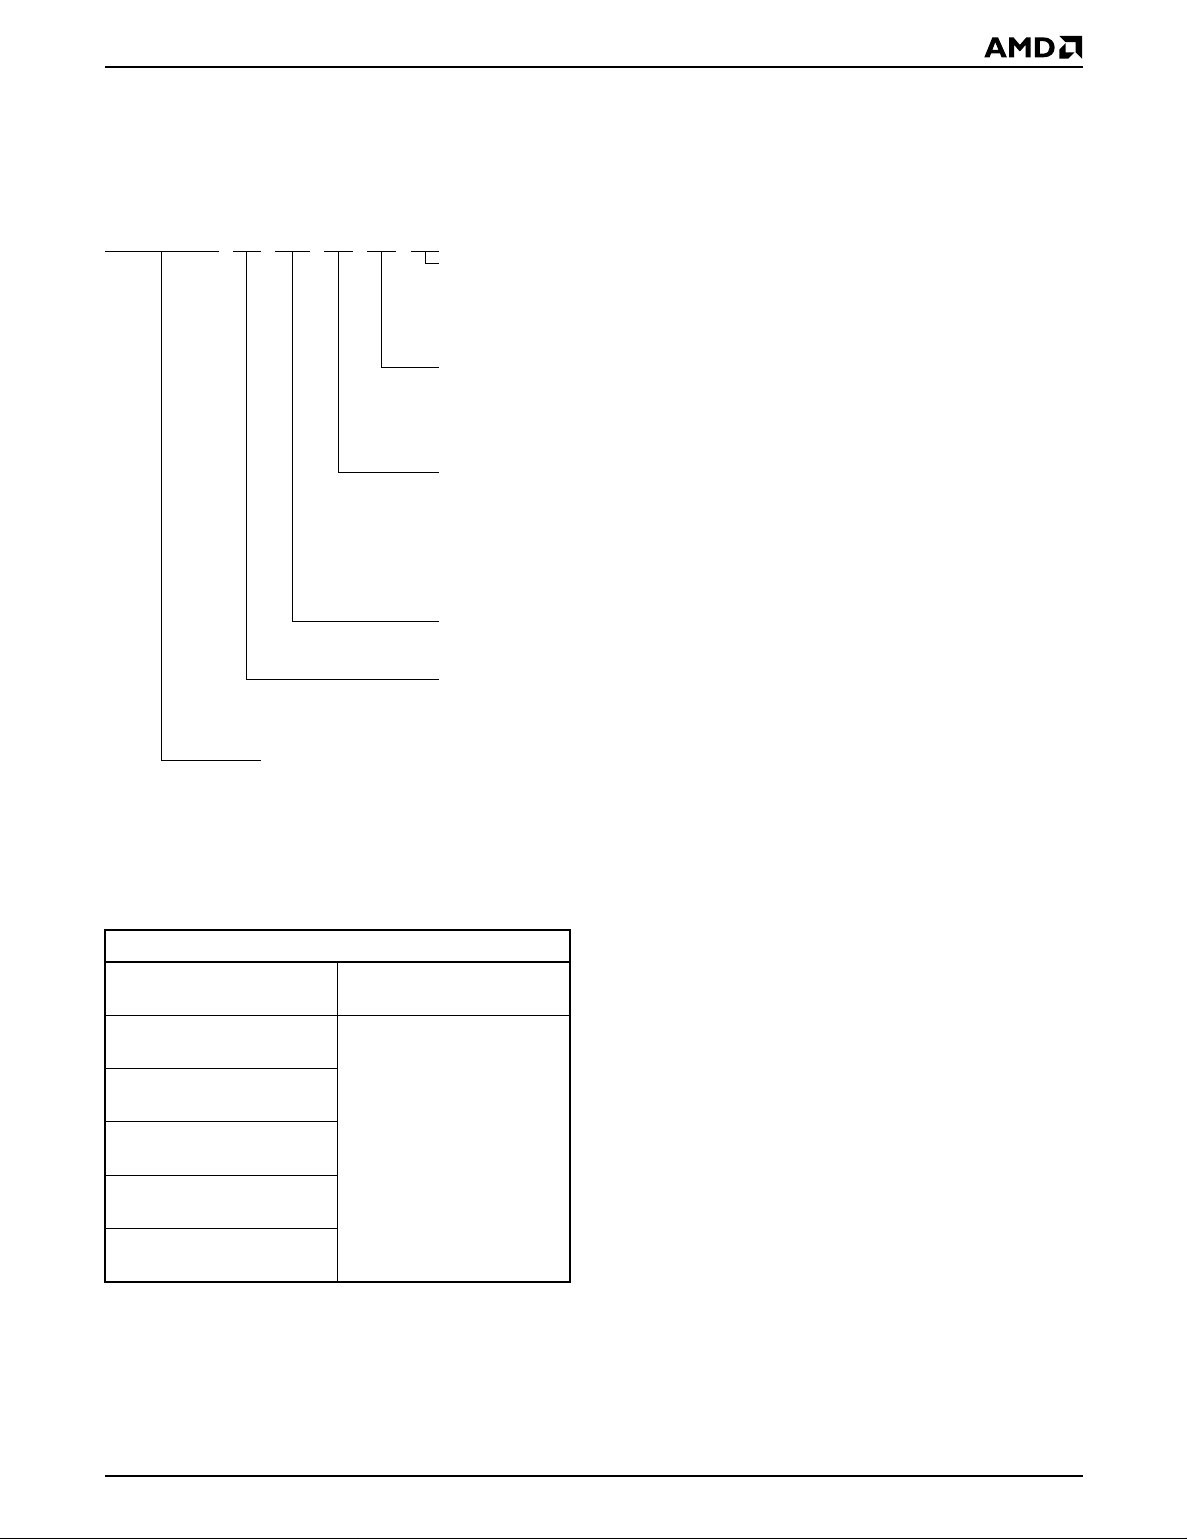
ORDERING INFORMATION
Standard Pr od ucts
AMD standard products are available in several packages and operating ranges. The order number (Valid Combination) is formed
by a combination of:
Am29F200B T -45 E C
OPTIONAL PROCESSING
Blank = Standard Processing
B=Burn-In
(Contact an AMD representative for more information)
TEMPERATURE RANGE
C = Commercial (0°C to +70°C)
I = Industrial (–40
E = Extended (–55
PACKAGE TY PE
E = 48-Pin Thin Small Outline Package (TSOP) Standard Pinout (TS 048)
F = 48-Pin Thin Small Outline Package (TSOP) Reverse Pinout (TSR048)
S = 44-Pin Small Outline Package (SO 044
This device is also available in Known Good Die (KGD) form. See publication number
21257 for more information.
SPEED OPTION
See Product Selector Guide and Valid Combinations
BOOT CODE SECTOR ARCHITECTURE
T = Top sector
B = Bottom sector
°C to +85°C)
°C to +125°C)
)
AM29F200BT-45,
AM29F200BB-45
AM29F200BT-50,
AM29F200BB-50
AM29F200BT-55,
AM29F200BB-55
AM29F200BT-70,
AM29F200BB-70
AM29F200BT-90,
AM29F200BB-90
AM29F200BT-120,
AM29F200BB-120
DEVICE NUMBER/DESCRIPTION
Am29F200B
2 Megabit (256 K x 8-Bit128 K x 16-Bit) CMOS Flash Memory
5.0 Volt-only Program and Erase
Valid Combinations
EC, EI, FC, FI, SC, SI
EC, EI, EE,
FC, FI, FE,
SC, SI, SE
Valid Combinations list configurations planned to be supported in volume for this device. Consult the local AMD sales
office to confirm availability of specific valid combinations and
to check on newly released combinations.
Valid Combinations
Am29F200B 7
Page 8
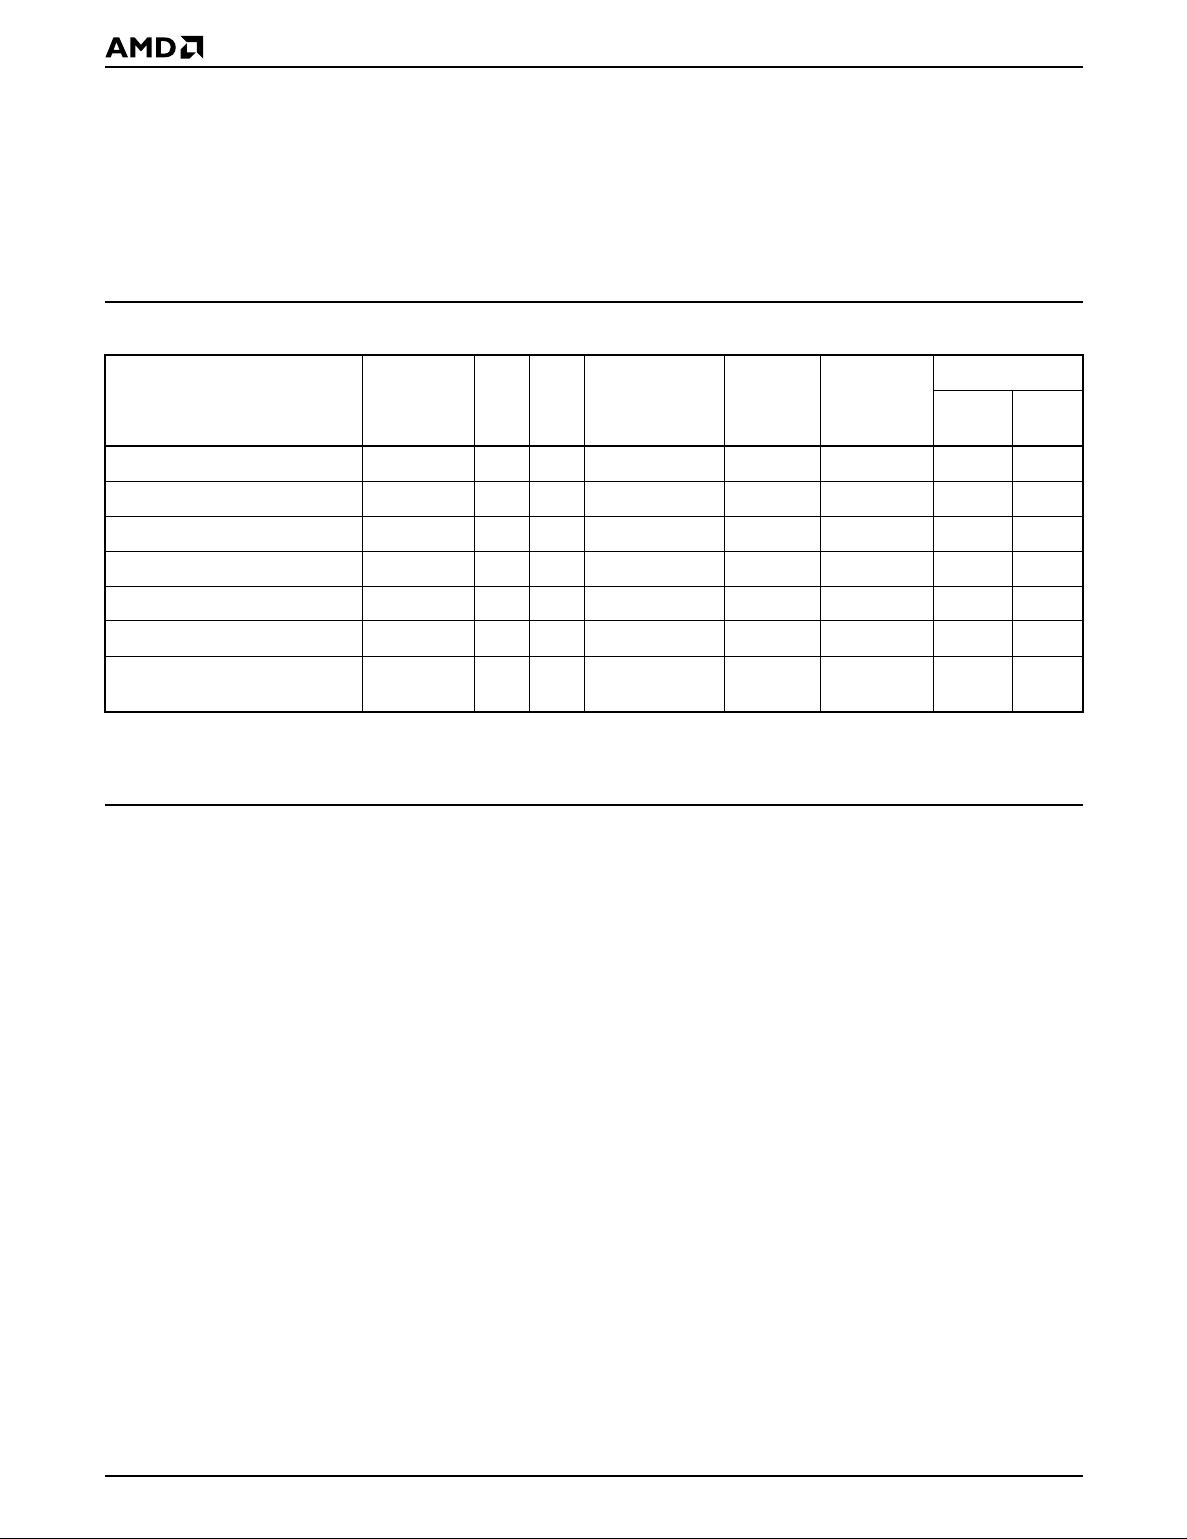
DEVICE BUS OPERATIONS
This section describes the requirements and use of the
device bus operations, which are initiated through the
internal command register. The command register
itself does not occupy any addressable memory location. The register is composed of l atches that store the
commands, along with the address and data information needed to execute the command. The contents of
Table 1. Am29F200B Device Bus Operations
the register serve as inputs to the i nternal state
machine. The state machine outputs dictate the function of the device. The appropriate device bus
operations table lists the inputs and control levels
required, and the resulting output. The following subsections describe each of these operations in furthe r
detail.
DQ8–DQ15
OUT
D
D
BYTE#
= V
IH
High-Z
High-Z
IN
IN
X
BYTE#
Operation CE# OE# WE# RESET# A0–A16 DQ0–DQ7
Read L L H H A
Write L H L H A
CMOS Standby V
TTL Standby H X X H X High-Z High-Z High-Z
Output Disable L H H H X High-Z High-Z High-Z
Hardware Reset X X X L X High-Z High-Z High-Z
Temporary Sector Unprotect
(See Note)
Legend:
L = Logic Low = V
Note: See the sections Sector Group Protection and Temporary Sector Unprotect for more information.
, H = Logic High = VIH, VID = 12.0 ± 0.5 V, X = Don’t Care, DIN = Data In, D
IL
Word/Byte Configuration
The BYTE# pin controls whether the device data I/O
pins DQ15–DQ0 operate in the by te or word configur ation. If the BYTE# pin is set at logic ‘1’, the device is in
word configuration, DQ15–DQ0 are active and controlled by CE# and OE#.
If the BYTE# pin is set at logic ‘0’, the device is in byte
configuration, and only data I/O pins DQ0–D Q7 are
active and controlled by CE# and OE#. The data I/O
pins DQ8–DQ14 are tri-stated, and the DQ15 pin is
used as an input for the LSB (A-1) address function.
Requirements for Reading Array Data
To read array data from the outputs, the system must
drive the CE# and OE# pins to V
control and selects the device. OE# is the output
control and gates array data to the output pins. WE#
should remain at V
BYTE# pin deter mines whether the device outputs
array data in words or bytes.
The internal state machine is set for reading arr ay data
upon device power-up, or after a hardware reset. This
ensures that no spurious alteration of the mem ory
. On x16 (word-wide) devices, the
IH
± 0.5 V X X VCC ± 0.5 V X High-Z High-Z High-Z
CC
XXX V
ID
content occurs during the power transition. No
command is neces sary in this mode to obtain ar ray
data. Standard microprocessor read cycles that assert
valid addresses on the device address inputs produce
valid data on the device data outputs. The device
remains enabled for read access until the command
register contents are altered.
See “Reading Array Data” for more information. Refer
to the AC Read Operations table for timing specifications and to the Read Operations Timings diagram for
the timing waveforms. I
table represents the active current specification for
reading array data.
Writing Commands/Command Sequences
. CE# is the power
IL
To write a command or command sequence (which
includes programming data to the device and erasing
sectors of memory), the system must drive WE# and
CE# to V
, and OE# to VIH.
IL
On x16 (word-wide) devices, for program operations,
the BYTE# pin determines whether the de vice accepts
program data in bytes or wor ds. Refer to “Word/Byte
Configuration” for more information.
IN
IN
A
IN
D
OUT
D
IN
D
IN
= Data Out, AIN = Address In
OUT
in the DC Characteristics
CC1
= V
D
IL
8 Am29F200B
Page 9
An erase operation can erase one sect or, multiple sectors, or the entire device. The Sector Address Tables
indicate the address space that each sector occupies.
A “sector address” consists of the address bits required
to uniquely select a sector. See the “Command Definitions” section for details on erasing a sector or the
entire chip, or suspending/resuming the erase
operation.
After the system writes the autoselect command
sequence, the devi ce enters the autoselect mode. The
system can then read autoselect codes from the
internal register (which is separate from the memory
array) on DQ7–DQ0. Sta ndard read cycle timings apply
in this mode. Refer to the “Autoselect Mode” and
“Autoselect Command Sequence” sections for more
information.
in the DC Characteristics table represents the
I
CC2
active current specification for the write mode. The “AC
Characteristics” section contains timing specification
tables and timing diagrams for write operations.
Program and Erase Operation Status
During an erase or program operation, the system ma y
check the status of the operation by reading the status
bits on DQ7–DQ0. Standard read cycle timings and I
CC
read specifications apply. Refer to “Write Operation
Status” for more information, and to each AC Characteristics section in the appropriate data sheet f or t iming
diagrams.
Standby Mode
When the system is not reading or writing to the device ,
it can place the device in the standby mode. In this
mode, current consumption is great ly reduc ed, and the
outputs are placed in the high impedance state, independent of the OE# input.
The device enters the CMOS standb y mode when CE#
and RESET# pins are both held at V
that this is a more restrict ed voltage range than V
The device enters the TTL standby mode when CE#
and RESET# pins are both held at V
requires standard access time (t
when the device is in either of these s tandby modes,
before it is ready to read data.
The device also enters the standby mode wh en the
RESET# pin is driven low. Refer to the next section,
“RESET#: Hardware Reset Pin”.
± 0.5 V. (Note
CC
. The device
IH
) for read access
CE
IH
If the device is deselected during erasure or programming, the device draws active current until the
operation is completed.
In the DC Characteristics tables, I
represents the
CC3
standby current specification.
RESET#: Hardware Reset Pin
The RESET# pin provides a hardw are method of resetting the device to readin g arr ay data. When the system
drives the RESET# pin low for at least a period of t
the device immediately terminates any operation in
progress, tristates all data output pins, and ignores all
read/write attempts for the duration o f the RESET#
pulse. The device also resets the internal state
machine to reading array data. The operation that was
interrupted should be reinitiated once the device is
ready to accept another command sequence, to
ensure data integrity.
Current is reduced for the duration of the RESET#
pulse. When RESET# is held at V
, the device enters
IL
the TTL standby mode; if RESET# is held at V
0.5 V, the device enters the CMOS standby mode.
The RESET# pin may be tied to the system reset cir-
cuitry. A system reset would thus also reset the Flash
memory, enabling the system to read the boot-up firmware from the Flash memory.
If RESET# is asserted during a program or erase operation, the RY/BY# pin remains a “0” (busy) until the
internal reset operation is complete, which requires a
time of t
(during Embedded Algorithms). The
READY
system can thus monitor RY/BY# to determine whether
the reset operation is complete. If RESET# is asserted
when a program or erase operation is not executing
(RY/BY# pin is “1”), the reset operation is completed
within a time of t
(not during Embe dded Algo-
READY
rithms). The system can read data t
RESET# pin returns to V
Refer to the AC Characteristics tables for RESET#
.)
parameters and timing diagram.
.
IH
Output Disable Mode
When the OE# input is at VIH, output from the device is
disabled. The output pins are placed in t he high impedance state.
after the
RH
SS
RP
,
±
Am29F200B 9
Page 10
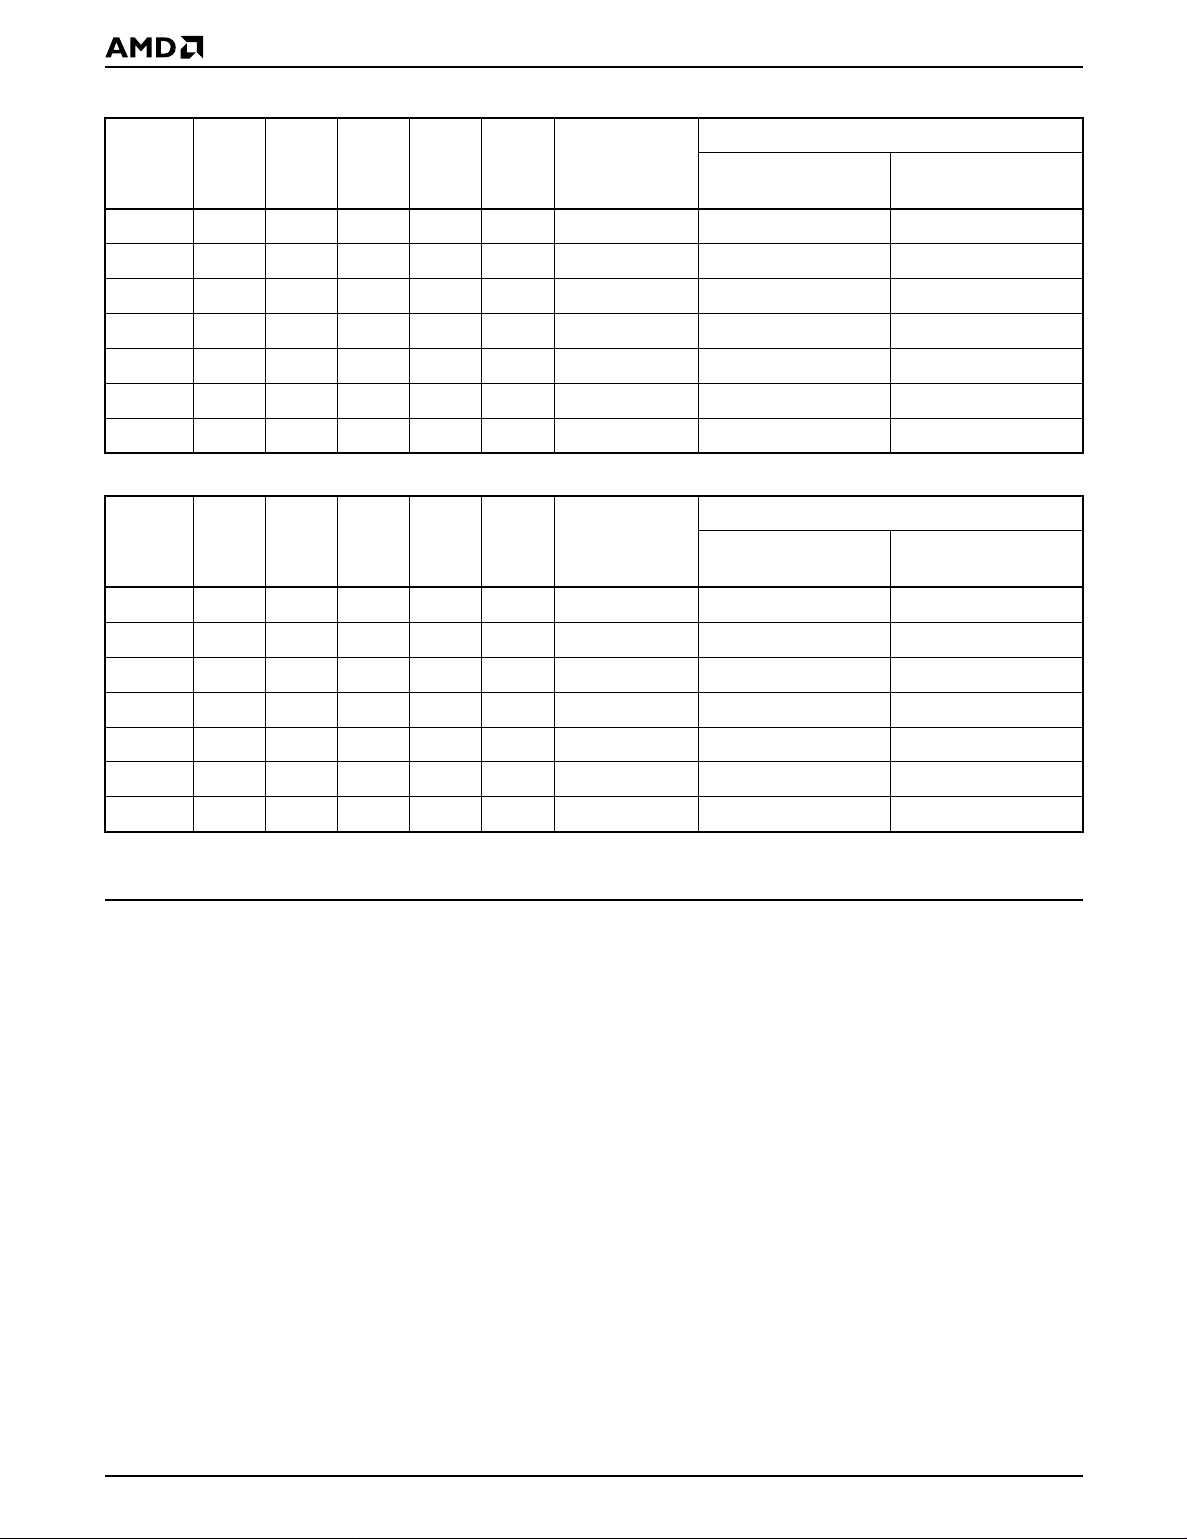
Table 2. Am29F200T Top Boo t Block Sector Address Table
Sector Size
(Kbytes/
Sector A16 A15 A14 A13 A12
SA0 0 0 X X X 64/32 00000h–0FFFFh 00000h–07FFFh
SA1 0 1 X X X 64/32 10000h–1FFFFh 08000h–0FFFFh
SA2 1 0 X X X 64/32 20000h–2FFFFh 10000h–17FFFh
SA3 1 1 0 X X 32/16 30000h–37FFFh 18000h–1BFFFh
SA4 1 1 1 0 0 8/4 38000h–39FFFh 1C000h–1CFFFh
SA5 1 1 1 0 1 8/4 3A000h–3BFFFh 1D000h–1DFFFh
SA6 1 1 1 1 X 16/8 3C000h–3FFFFh 1E000h–1FFFFh
Kwords)
Address Range (in hexadecim al )
(x8)
Address Range
Address Range
(x16)
Table 3. Am29F200B Bottom Boot Block Sector Address Table
Sector Size
(Kbytes/
Sector A16 A15 A14 A13 A12
SA0 0 0 0 0 X 16/8 00000h–03FFFh 00000h–01FFFh
SA1 0 0 0 1 0 8/4 04000h–05FFFh 02000h–02FFFh
SA2 0 0 0 1 1 8/4 06000h–07FFFh 03000h–03FFFh
SA3 0 0 1 X X 32/16 08000h–0FFFFh 04000h–07FFFh
Kwords)
Address Range (in hexadecim al )
(x8)
Address Range
Address Range
(x16)
SA4 0 1 X X X 64/32 10000h–1FFFFh 08000h–0FFFFh
SA5 1 0 X X X 64/32 20000h–2FFFFh 10000h–17FFFh
SA6 1 1 X X X 64/32 30000h–3FFFFh 18000h–1FFFFh
Note for Tables 2 and 3: Address range is A16:A-1 in byte mode and A16:A0 in word mode. See the “Word/Byte Configuration”
sectionfor more information.
Autoselect Mode
The autoselect mode provides manufacturer and
device identification, and sector protection verification,
through identifier codes output on DQ7–DQ0. This
mode is primarily intended for progr amming equipment
to automatically match a device to be progr ammed with
its correspondi ng programming al gorithm. However,
the autoselect codes can also be accessed in-system
through the command register.
When using programming equipment, the autoselect
mode requires V
(11.5 V to 12.5 V) on address pin
ID
A9. Address pins A6, A1, and A0 must be as shown in
Autoselect Codes (High Voltage Method) table. In addition, when verifying sector protection, the sector
address must appear on the appropriate highest order
address bits. Refer to the corresponding Sector
Address Tables. The Command D efinitions table
shows the remaining address bits that are don’t care.
When all necessary bits have been set as required, the
programming equipment may then read the corresponding identifier code on DQ7–DQ0.
To access the autoselect codes in-system, the host
system can issue the autoselect command via the
command register, as shown in the Command Definitions table. This method does not require V
. See
ID
“Autoselect Command Sequence” for details on using
the autoselect mode.
10 Am29F200B
Page 11
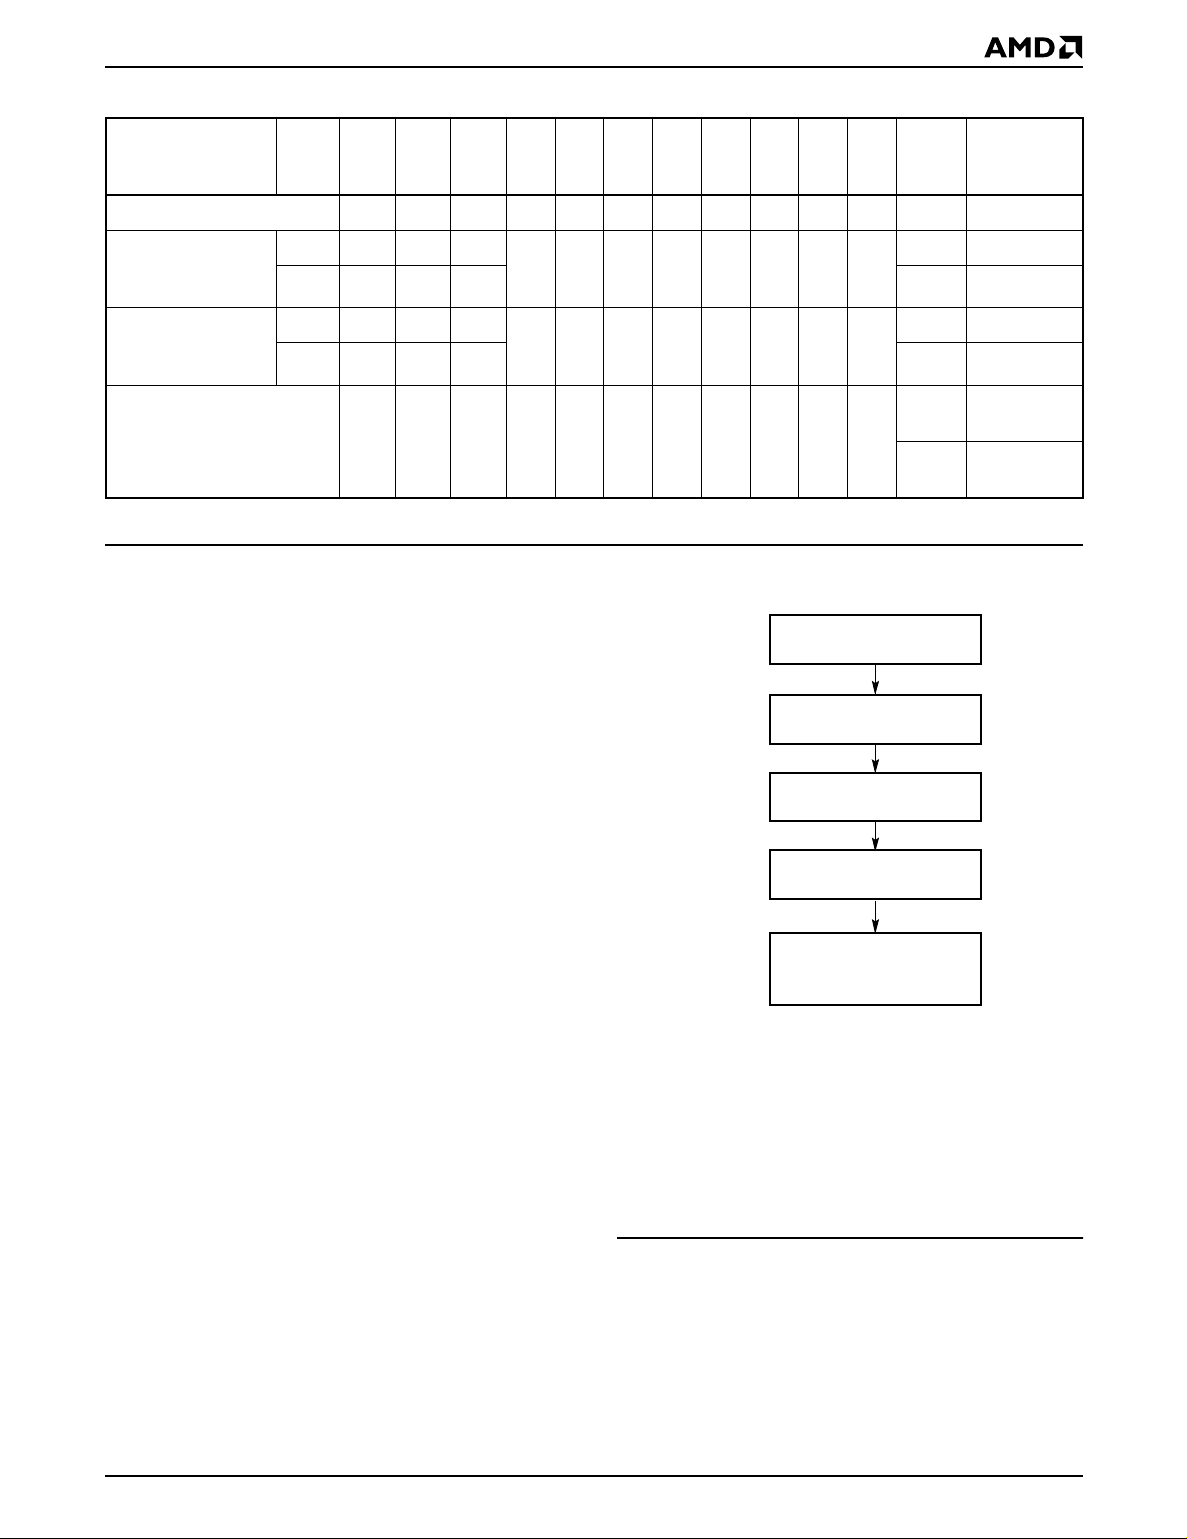
Table 4. Am29F200B Autoselect Codes (High Voltage Method)
Description Mode CE# OE# WE#
A16
to
A12
A11
to
A10 A9
A8
to
A7 A6
A5
to
A2 A1 A0
DQ8
to
DQ15
DQ7
to
DQ0
Manufacturer ID: AMD L L H X X V
Device ID:
Am29F200B
(Top Boot Block)
Device ID:
Am29F200B
(Bottom Boot Block)
Sector Protection Verification L L H SA X V
L = Logic Low = VIL, H = Logic High = VIH, SA = Sector Address, X = Don’t care.
Word L L H
XXVIDXLXLH
Byte L L H X 51h
Word L L H
XXVIDXLXLH
Byte L L H X 57h
XLXLL X 01h
ID
XLXHL
ID
Sector Protection/Unprotection
The hardware sector protection feature disables both
program and erase operations in any sect or. The hardware sector unprotection feature re-enables both
program and erase operations in previously protected
sectors.
Sector protection/unprotection must be implemented
using programming equipment. The procedure
requires a high voltage (V
control pins. Details on this method are provided in a
supplement, publication number 20551. Contact an
AMD representative to obtain a cop y of the appropriate
document.
) on address pin A9 and the
ID
22h 51h
22h 57h
X
X
START
RESET# = V
(Note 1)
Perform Erase or
Program Operations
RESET# = V
ID
IH
01h
(protected)
00h
(unprotected)
The device is shipped with all sectors unprotected.
AMD offers the option of programming and protecting
sectors at its factory prior to shipping the device
through AMD’s ExpressFlash™ Servic e. Contact an
AMD representative for details.
It is possible to determine whether a sector is protected
or unprotected. See “Autoselect Mode” for details.
Temporary Sector Unprotect
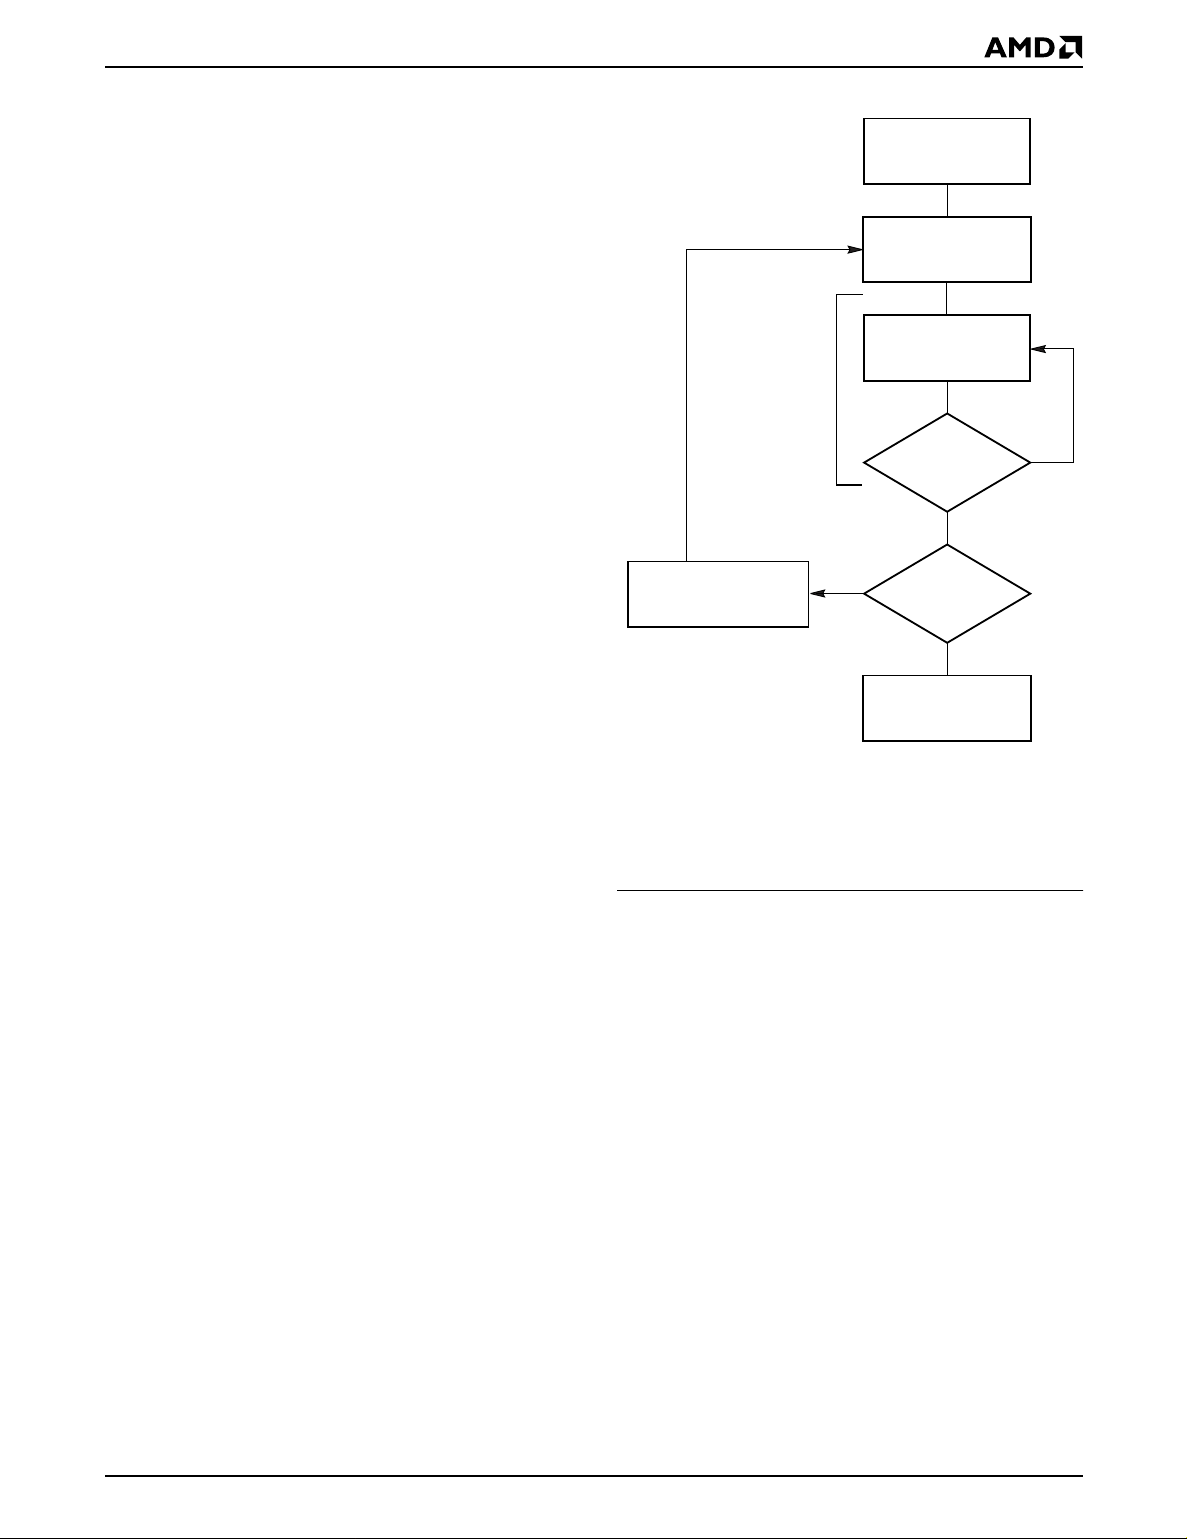
This feature allows temporary unpr otection of previously protected sectors to change data in-system. The
Sector Unprotect mode is activated by setting the
RESET# pin to V
tected sectors can be programmed or erased by
selecting the sector addresses. Once V
from the RESET# pin, all the previously protected
sectors are protected again. Figure 1 shows the algorithm, and the Temporary Se ctor Unprotect diagram
(Figure 18) shows the timing waveforms, for this
feature.
. During this mode, former ly pro-
ID
is removed
ID
Am29F200B 11
Temporary Sector
Unprotect
Completed (Note 2)
21526B-6
Notes:
1. All protected sectors unprotected.
2. All previously protected sectors are protected once
again.
Figure 1. Temporary Sector Unprotect Operati on
Hardware Data Protection
The command sequence requirement of unlock cycles
for programming or erasing provides data protection
against inadvertent writes (refer to the Command Definitions table). In addition, the following hardware data
protection measures pre vent a ccidental eras ure or pro-
Page 12
gramming, which might otherwise be caused by
spurious system level signals during V
power-up and
CC
power-down transitions, or from system noise.
Low V
When V
accept any write cycles. This protects data during V
Write Inhibit
CC
is less than V
CC
, the device does not
LKO
CC
power-up and power-down. The command register and
all internal program/erase circuits are disabled, and the
device resets. Subsequent writes are ignored until V
is greater than V
. The system must provide the
LKO
CC
proper signals to the control pins to prevent unintentional writes when V
is greater than V
CC
LKO
.
COMMAND DEFINITIONS
Writing specific address and data commands or
sequences into the command register initiates device
operations. The Command Definitions tab le defines the
valid register command sequences. Writing incorrect
address and data values or writing them in the
improper sequence resets the device t o reading array
data.
All addresses are latched on the falling edge of WE# or
CE#, whichever happens later. All data is latched on
the rising edge of WE# or CE#, whichever happens
first. Refer to the appropriate timing diagrams in the
“AC Characteristics” section.
Reading Array Data
The device is automatically set to reading array data
after device power-up. No commands are required to
retrieve data. The device is also ready to read array
data after comp leting an Embedded Program o r
Embedded Erase algorithm.
After the device accepts an Er ase Suspend command,
the device enters the Erase Suspend mode. The
system can read array data using the standard read
timings, except that if it reads at an address within
erase-suspended sectors, the device outputs status
data. After completing a programming operation in the
Erase Suspend mode, the system may once again
read array data with the same exception. See “Erase
Suspend/Erase Resume Commands” for more information on this mode.
must
The system
enable the device for reading array data if DQ5 goes
high, or while in the autoselect mode. See the “Reset
Command” section, next.
See also “Requirements for Reading Arr a y Data” in the
“Device Bus Operations” section for more information.
The Read Operations table provides the read parame-
issue the reset command to re-
Write Pulse “Glitch” Protection
Noise pulses of less than 5 ns (typical) on OE#, CE# or
WE# do not initiate a write cycle.
Logical Inhibit
Write cycles are inhibited by holding any one of OE# =
, CE# = VIH or WE# = VIH. To initiate a write cycle,
V
IL
CE# and WE# must be a logical zero while OE# is a
logical one.
Power-Up Write Inhibit
If WE# = CE# = V
and OE# = VIH during power up , the
IL
device does not accept commands on the rising edge
of WE#. The internal state mac hine is automatically
reset to reading array data on power-up.
ters, and Read Operation Timings diagram shows the
timing diagram.
Reset Command
Writing the reset co mmand to the device resets the
device to reading array data. Address bits are don’t
care for this command.
The reset command may be written between the
sequence cycles in an erase command sequence
before erasing begins . This resets the device t o reading
array data. Once erasure begins, however, the device
ignores reset commands until the operation is
complete.
The reset command may be written between the
sequence cycles in a program command sequence
before programming begins. This resets the device to
reading array data (also applies to programming in
Erase Suspend mode). Once programming begins,
however, the device ignores reset commands until the
operation is complete.
The reset command may be written between the
sequence cycles in an autoselect command sequence.
Once in the autoselect mode, t he reset c ommand
must
be written to return to reading array data (also applies
to autoselect during Erase Suspend).
If DQ5 goes high during a program or erase operation,
writing the reset command returns the device to
reading array data (also applies during Erase
Suspend).
Autoselect Command Sequence
The autoselect c ommand sequenc e allows the host
system to access the manufacturer and devices codes,
and determine whether or not a sector is protected.
The Command Definitions table shows the address
and data requirements. This method is an a lternative to
that shown in the Autoselect Codes (High Voltage
12 Am29F200B
Page 13
Method) table, which is intended for PROM programmers and requires V
on address bit A9.
ID
The autoselect command sequence is initiated by
writing two unlock cycles, followed by the autoselect
command. The device then enters the autoselect
mode, and the system may read at any address any
number of times, without initiating another command
sequence.
A read cycle at address XX00h retrieves the manufacturer code. A read cycle at address XX01h in word
mode (or 02h in byte mode) returns the device code. A
read cycle containing a sector address (SA) and the
address 02h in word mod e (or 04h in byte mode)
returns 01h if that s ector is protected, or 00h if it is
unprotected. Refer to the Sector Address tables for
valid sector addresses.
The system must write the reset command to exit the
autoselect mode and return to reading array data.
Embedded
Program
algorithm
in progress
START
Write Program
Command Sequence
Data Poll
from System
Verify Data?
Yes
No
Word/Byte Program Command Sequence
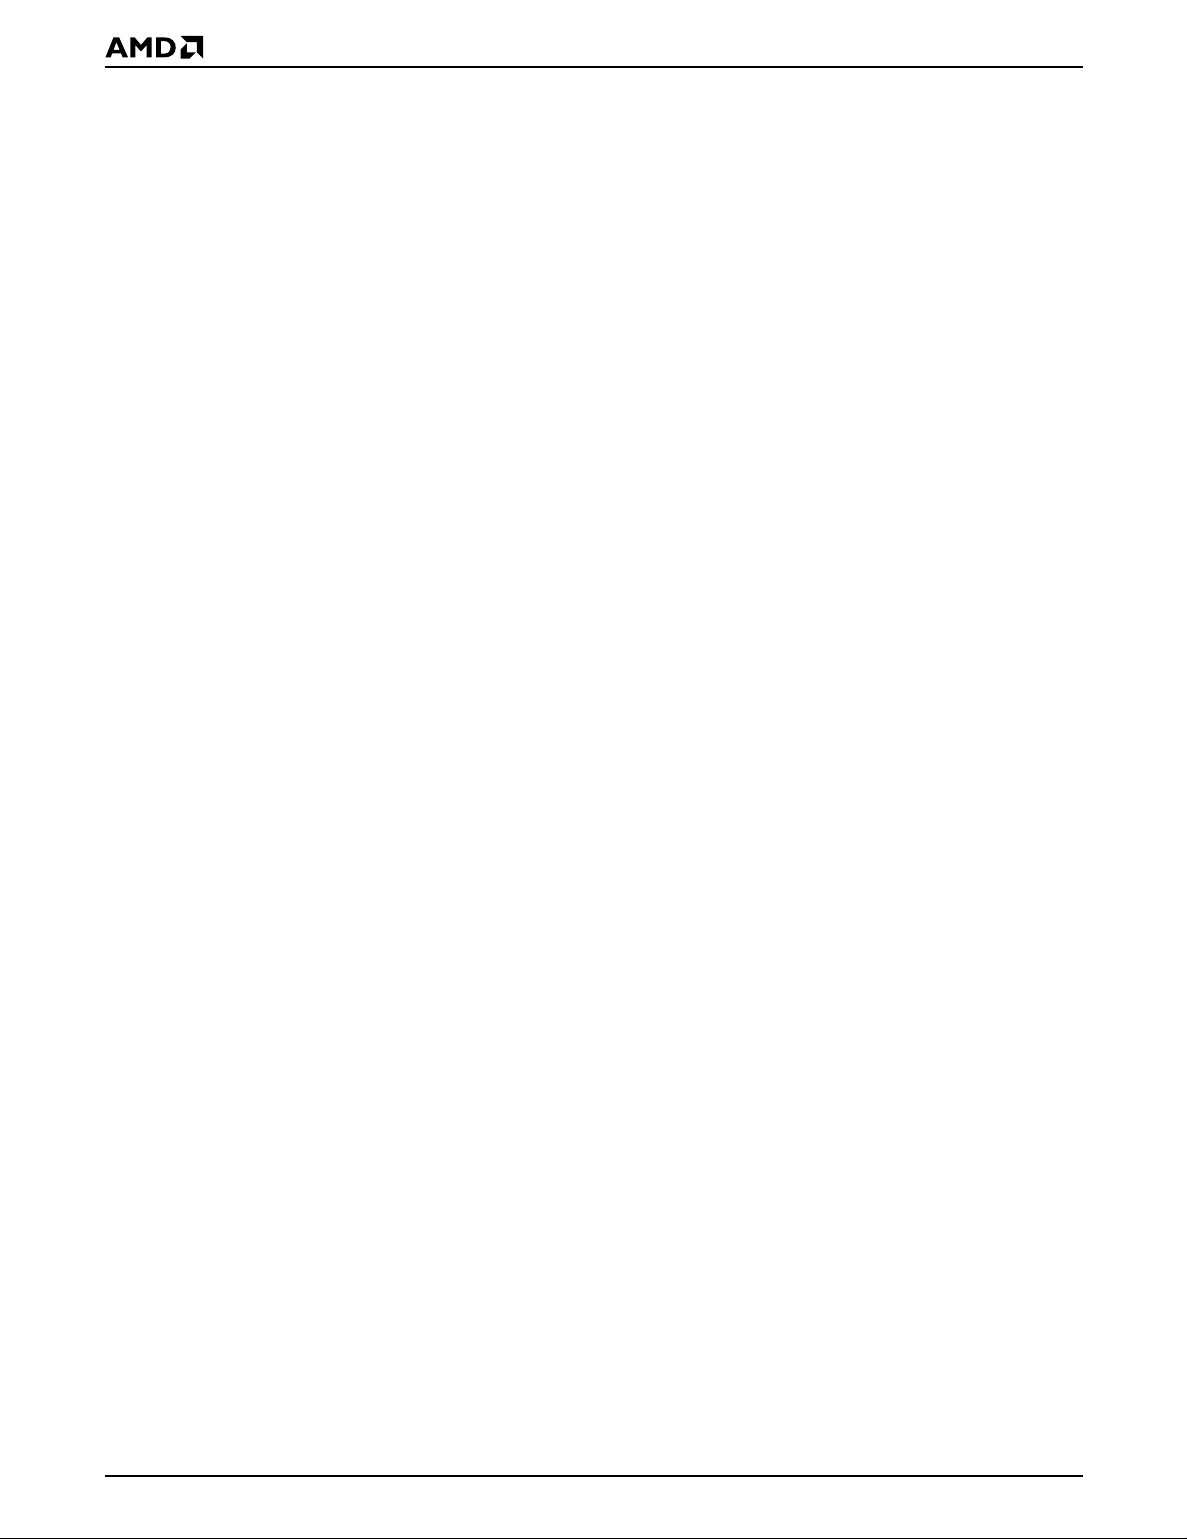
The system may program the device by byte or word,
on depending on the state of the BYTE# pin. Progr amming is a four-bus-cycle operation. The program
command sequence is initiated by writing two unlock
write cycles, follo wed by t he program set-up command.
The program address and data are written next, which
in turn initiate the Embedded Program algorithm. The
not
system is
ings. The device automatically provides internally
generated program pulses and verify the programmed
cell margin. The Command Definitions take shows the
address and data requirements for the byte program
command sequence.
When the Embedded Program algorithm is complete,
the device then returns to reading array data and
addresses are no longer latched. The system can
determine the status of the program operation by using
DQ7, DQ6, or RY/BY#. See “Write Ope ration Status”
for information on these status bits.
Any commands written to the device during the
Embedded Program Algorithm are ignored. Not e that a
hardware reset immediately terminates the programming operation. The program command sequence
should be reinitiated once the device has reset to
reading array data, to ensure data integrity.
Programming is allowed in any sequence an d across
sector boundaries. A bit cannot be programmed
from a “0” back to a “1”. Attempting to do so may halt
the operation and set DQ5 to “1”, or cause the Data#
Polling algorithm to indicate the op eration was successful. However, a succeeding read will show that the
data is still “0”. Only erase operations can convert a “0”
to a “1”.
required to provide further controls or tim-
Increment Address
Note: See the appropriate Command Definitions table for
program command sequence.
No
Last Address?
Yes
Programming
Completed
21526B-6
Figure 2. Program Operation
Chip Erase Command Sequence
Chip erase is a six-bu s-cycle oper ation. The chip er ase
command sequence is initiated by writing two unlock
cycles, followed by a set-up command. Two additional
unlock write cycles are then followed by the chip erase
command, which in turn invokes the Embedded Erase
not
algorithm. The device does
preprogram prior to erase. The Embedded Erase algorithm automatically preprograms and verifies the entire
memory for an all zero data patter n prior to electr ical
erase. The system is not required to provide any controls or timings during these operations. The Command
Definitions table shows the address and data requirements for the chip erase command sequence.
Any commands written to the chip during the
Embedded Erase algorithm are ignored. Note that a
hardware reset during the chip eras e operat ion immediately terminates the operation. The Chip Erase
command sequence should be reinitiated once the
device has returned to reading array data, to ensure
data integrity.
require the system to
Am29F200B 13
Page 14
The system can determine the status of the erase oper-
ation by using DQ7, DQ6, DQ2, or RY/BY#. See “Write
Operation Status” for information on these status bits.
When the Embedded Erase algorithm is complete, the
device returns to reading arra y data and addresses are
no longer latched.
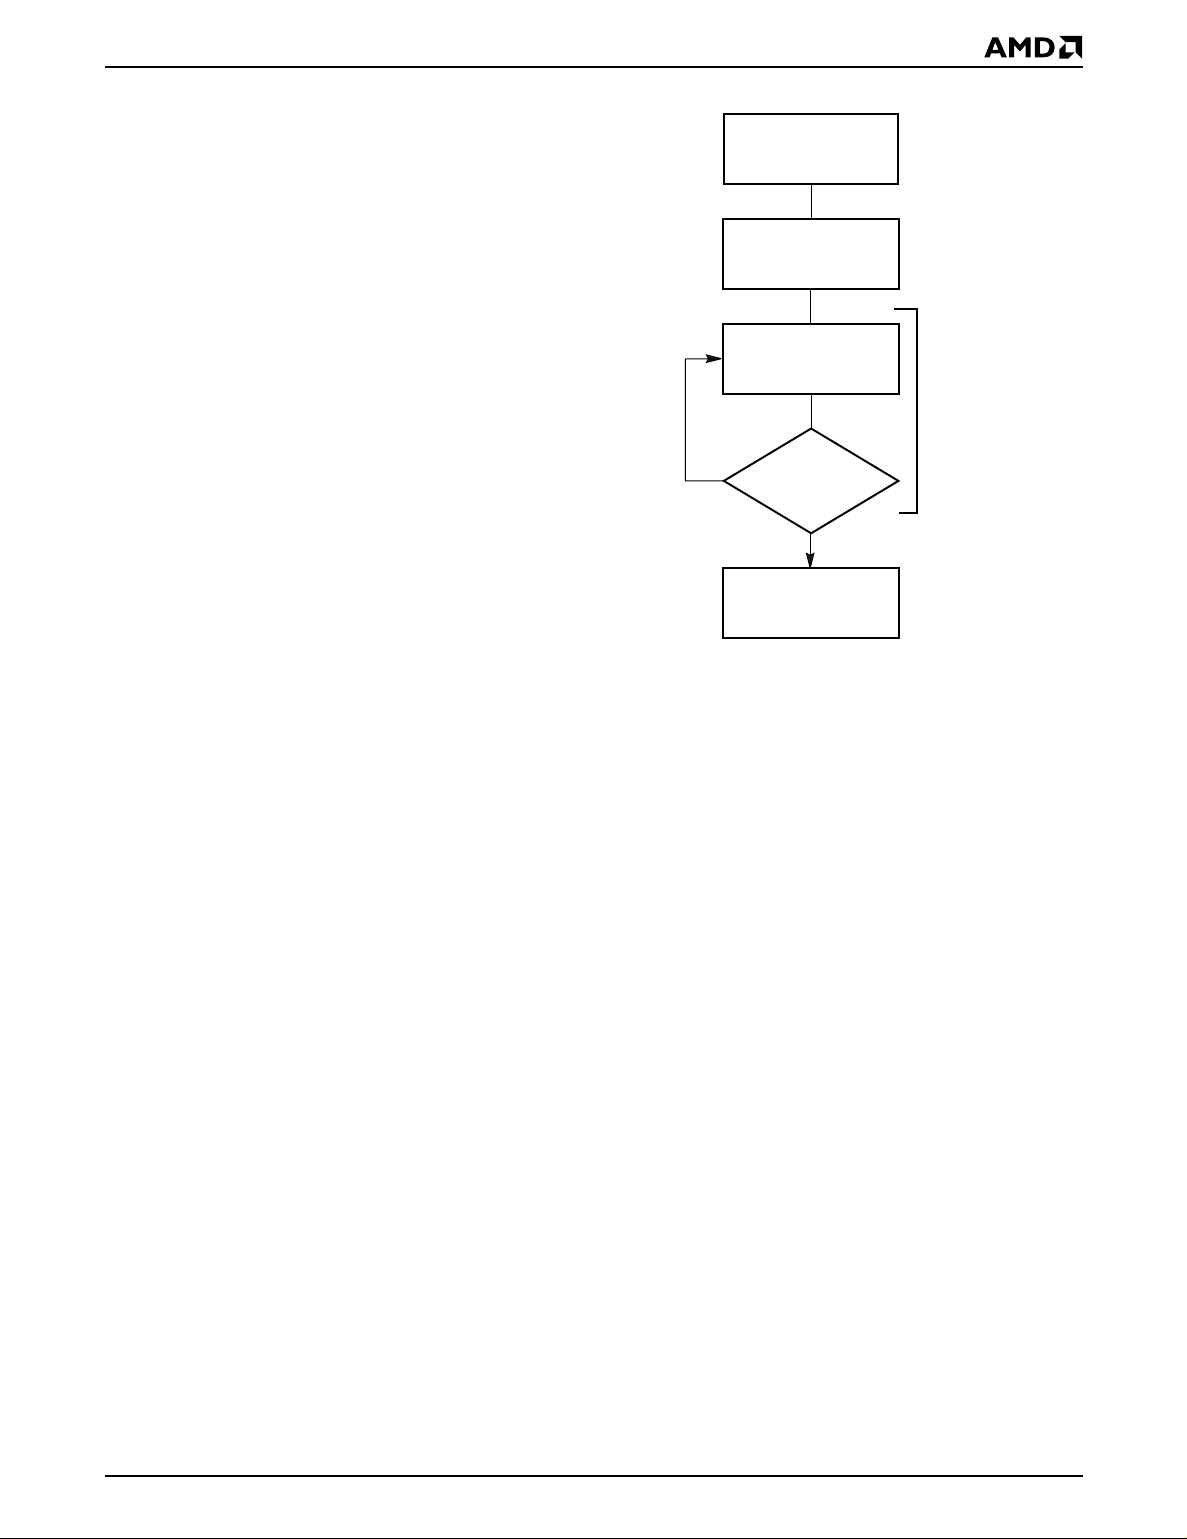
Figure 3 illustrates the algorithm for the erase operation. See the Erase/Program Operations tables in “AC
Characteristics” for parameters , and to the Chip/Sector
Erase Operation Timings for timing waveforms.
Sector Erase Command Sequence
Sector erase is a six bus cycle operation. The sector
erase command sequence is initiated by writing two
unlock cycles, followed by a set-up command. Two
additional unlock write cycles are then followed by the
address of the sector to be erased, and the sector
erase command. The Command Definitions table
shows the address and data requirements for the
sector erase command sequence.
not
The device does
the memory prior to erase. The Embedded Erase algorithm automatically programs and verifies the sector f or
an all zero data pattern prior to electrical erase. The
system is not required to provide any controls or
timings during these operations.
After the command sequence is written, a sector erase
time-out of 50 µs begi ns. During the time-out per iod,
additional sector addresses and sector erase commands may be written. Loading the sector erase buffer
may be done in any sequence, and the number of
sectors may be from one sector to all sectors . The time
between these additional cycles must be less than 50
µs, otherwise the last address and command might not
be accepted, and erasure may begin. It is recommended that processor interrupts be disabled during
this time to ensure all commands are accepted. The
interrupts can be re-enabled after the las t Sector Erase
command is written. If the time between additional
sector erase commands can be assumed to be less
than 50 µs, the system need not m onitor DQ3. Any
command other than Sector Erase or E rase
Suspend during the time-out period resets the
device to reading array data. The system must
rewrite the command sequence and any additiona l
sector addresses and commands.
The system can monitor DQ3 to determine if the sector
erase timer has timed out. (See the “DQ3: Sec tor Erase
Timer” section.) The time-out be gins from the rising
edge of the final WE# pulse in the command sequence .
Once the sector erase operation has begun, onl y the
Erase Suspend command is valid. All other commands
are ignored. Note th at a hardware reset during the
sector erase operation immedia tely terminates the
operation. The Sec tor Erase command sequence
require the system to preprogram
should be reinitiated onc e the device has returned to
reading array data, to ensure data integrity.
When the Embedded Erase algorithm is complete, the
device returns to reading arra y data and addr esses are
no longer latched. The system can determi ne the
status of the erase operation b y using DQ7, DQ6, DQ2,
or RY/BY#. Refer to “Write Operation Status” for information on these status bits.
Figure 3 illustrates the algorithm for the erase operation. Refer to the Erase/Program Operations tables in
the “AC Characteristics” section for parameters, and to
the Sector Erase Operations Timing diagr am for timing
waveforms.
Erase Suspend/Erase Resume Commands
The Erase Suspend command allows the system to
interrupt a sector erase operation and then read data
from, or program data to, any sector not selected for
erasure. This command is valid only during the sector
erase operation, including the 50 µs time-out period
during the sector erase c ommand sequence. The
Erase Suspend command is ignored if written during
the chip erase operation or Embedded Program algorithm. Writing the Erase Suspend command during the
Sector Erase time-out immediately terminates the
time-out period and suspends the erase operation.
Addresses are “don’t-cares” wh en writing the Erase
Suspend command.
When the Erase Suspend command is written during a
sector erase operation, the de vice requires a maximum
of 20 µs to suspend the erase operation. However,
when the Erase Suspend command is written during
the sector erase time-out, the device immediately terminates the time-out period and suspends the erase
operation.
After the erase operation has been suspended, the
system can read array data from or program data to
any sector not selected for erasu re. (The de vice “er ase
suspends” all sectors selected for erasure.) Normal
read and write timings and command definitions apply.
Reading at any address within erase-suspended
sectors produces status data on DQ7–DQ0. The
system can use DQ7, or DQ6 and DQ2 together, to
determine if a sector is actively erasing or is eras e-suspended. See “Write Operation Status” for information
on these status bits.
After an erase-suspended program operation is complete, the system c an once again r ead arra y d ata within
non-suspended sectors. The system can determine
the status of the program operation using the DQ7 or
DQ6 status bits, just as in the standard program operation. See “Write Operation Status” for more
information.
The system may also write the autoselect command
sequence when the device is in the Erase Suspend
14 Am29F200B
Page 15
mode. The device allows reading autoselect codes
even at addresses within erasing sectors, since the
codes are not stored in the memory array. When the
device exits the autoselect mode, the device reverts to
the Erase Suspend mode, and is ready for another
valid operation. See “Autoselect Command Sequence”
for more information.
The system must write the Erase Resume command
(address bits are “don’t care”) to exit the erase suspend
mode and continue the sector erase operat ion. Further
writes of the Resume command are ignored. Another
Erase Suspend command can be written after the
device has resumed erasing.
START
Write Erase
Command Sequence
Data Poll
from System
No
Data = FFh?
Erasure Completed
Embedded
Erase
algorithm
in progress
Yes
21526B-7
Notes:
1. See the appropriate Command Definitions table for erase
command sequence.
2. See “DQ3: Sector Erase Timer” for more information.
Figure 3. Erase Operation
Am29F200B 15
Page 16
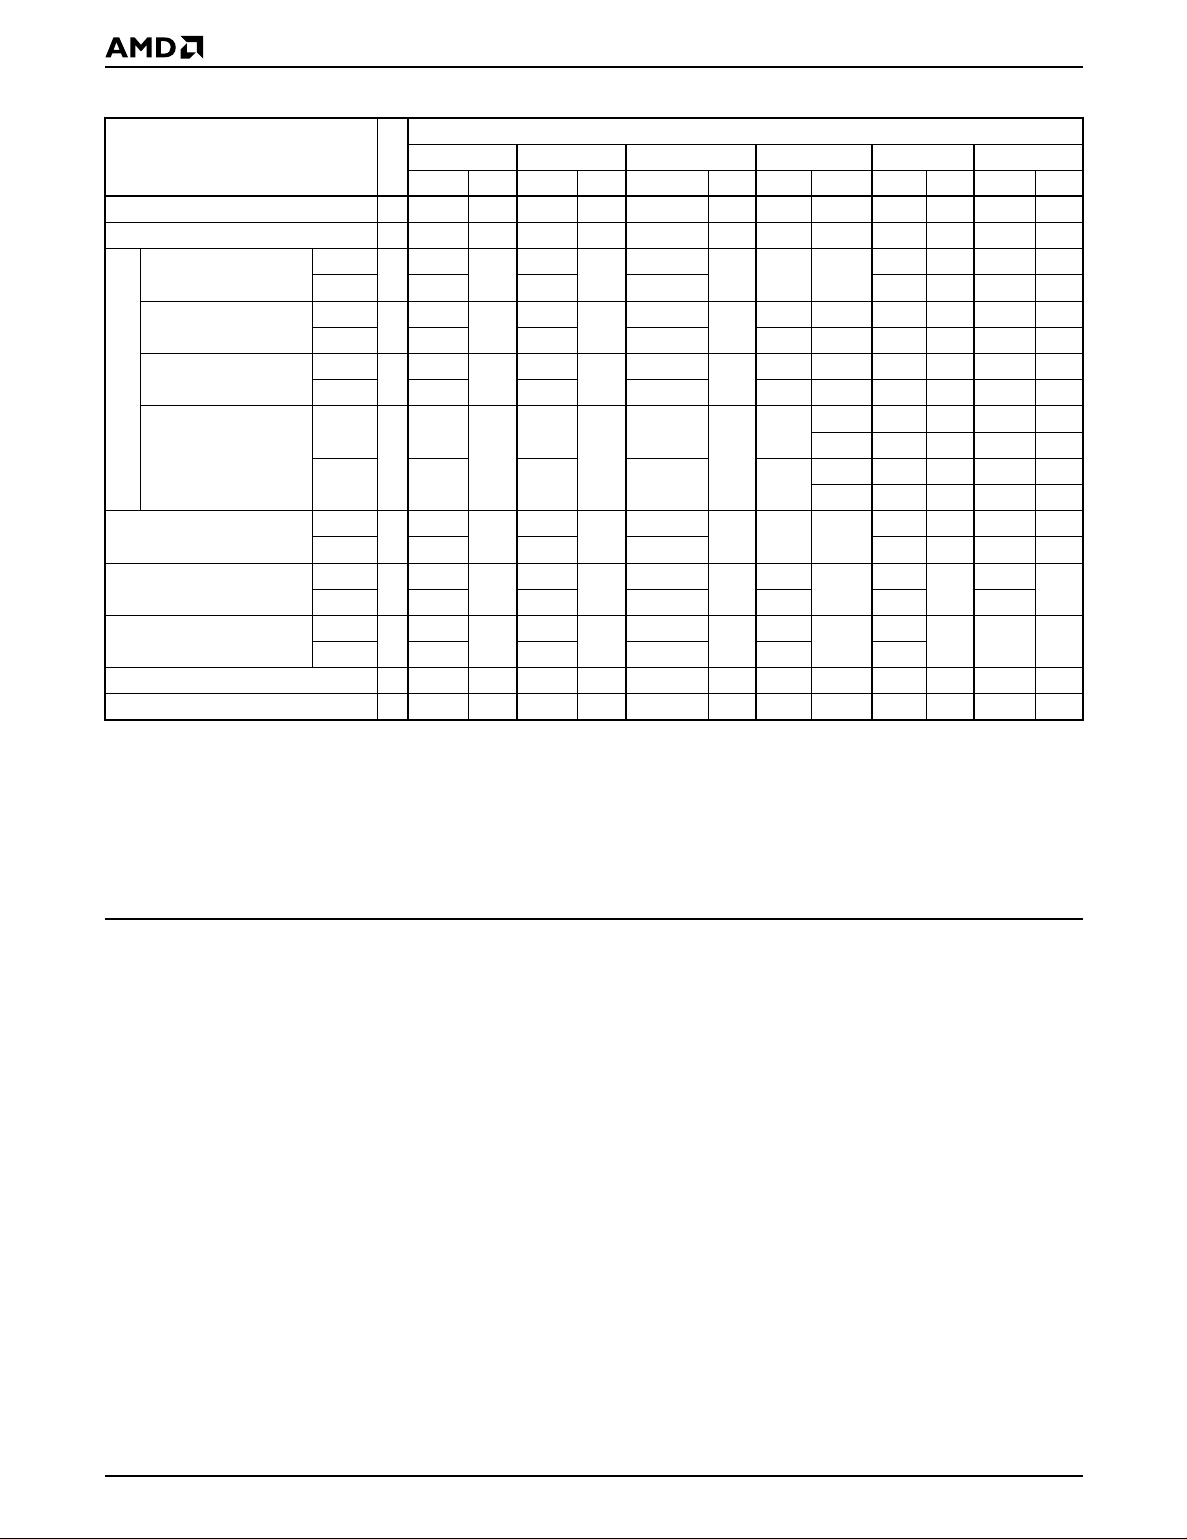
Table 5. Am29F200B Command Definitions
Command
Sequence
(Note 1)
Read (Note 6) 1 RA RD
Reset (Note 7) 1 XXX F0
Manufacturer ID
Device ID,
Top Boot Block
Device ID,
Bottom Boot Block
Autoselect (Note 8)
Sector Protect Verify
(Note 9)
Program
Chip Erase
Sector Erase
Erase Suspend (Note 10) 1 XXX B0
Erase Resume (Note 11) 1 XXX 30
Word
Byte AAA 555 AAA
Word
Byte AAA 555 AAA
Word
Byte AAA 555 AAA
Word
Byte AAA 555 AAA
Word
Byte AAA 555 AAA
Word
Byte AAA 555 AAA AAA 555 AAA
Word
Byte AAA 555 AAA AAA 555
First Second Third Fourth Fifth Sixth
Addr Data Addr Data Addr Data Addr Data Addr Data Addr Data
Cycles
555
4
4
4
4
4
6
6
555
555
555
555
555
555
AA
AA
AA
AA
AA
AA
AA
2AA
2AA
2AA
2AA
2AA
2AA
2AA
55
55
55
55
55
55
55
Bus Cycles (Notes 2–5)
555
555
555
555
555
555
555
90 X00 01
X01 2251
90
X02
X01 2257
90
X02
(SA)
X02
90
(SA)
X04
A0 PA PD
555
80
555
80
51
57
XX00
XX01
00
01
AA
AA
2AA
2AA
555
55
55 SA 30
10
Legend:
X = Don’t care
RA = Address of the memory location to be read.
RD = Data read from location RA during read operation.
PA = Address of the memory location to be programmed.
Addresses latch on the falling edge of the WE# or CE# pulse,
whichever happens later.
Notes:
1. See Table 1 for description of bus operations.
2. All values are in hexadecimal.
3. Except when reading array or autoselect data, all bus cycles
are write operations.
4. Data bits DQ15–DQ8 are don’t cares for unlock and
command cycles.
5. Address bits A16–A11 are don’t cares for unlock and
command cycles, unless SA or PA required.
6. No unlock or command cycles required when reading array
data.
7. The Reset command is required to return to reading array
data when device is in the autoselect mode, or if DQ5 goes
high (while the device is providing status da ta).
PD = Data to be programmed at location PA. Data latches on the
rising edge of WE# or CE# pulse, whichever happens first.
SA = Address of the sector to be verified (in autoselect mode) or
erased. Address bits A16–A12 uniquely select any sector.
8. The fourth cycle of the autoselect command sequence is a
read cycle.
9. The data is 00h for an unprotected sector and 01h for a
protected sector. See “Autoselect Command Sequence” for
more information.
10. The system may read and program in non-erasing sectors, or
enter the autoselect mode, when in the Erase Suspend
mode. The Erase Suspend command is valid only during a
sector erase operation.
11. The Erase Resume command is valid only during the Erase
Suspend mode.
16 Am29F200B
Page 17
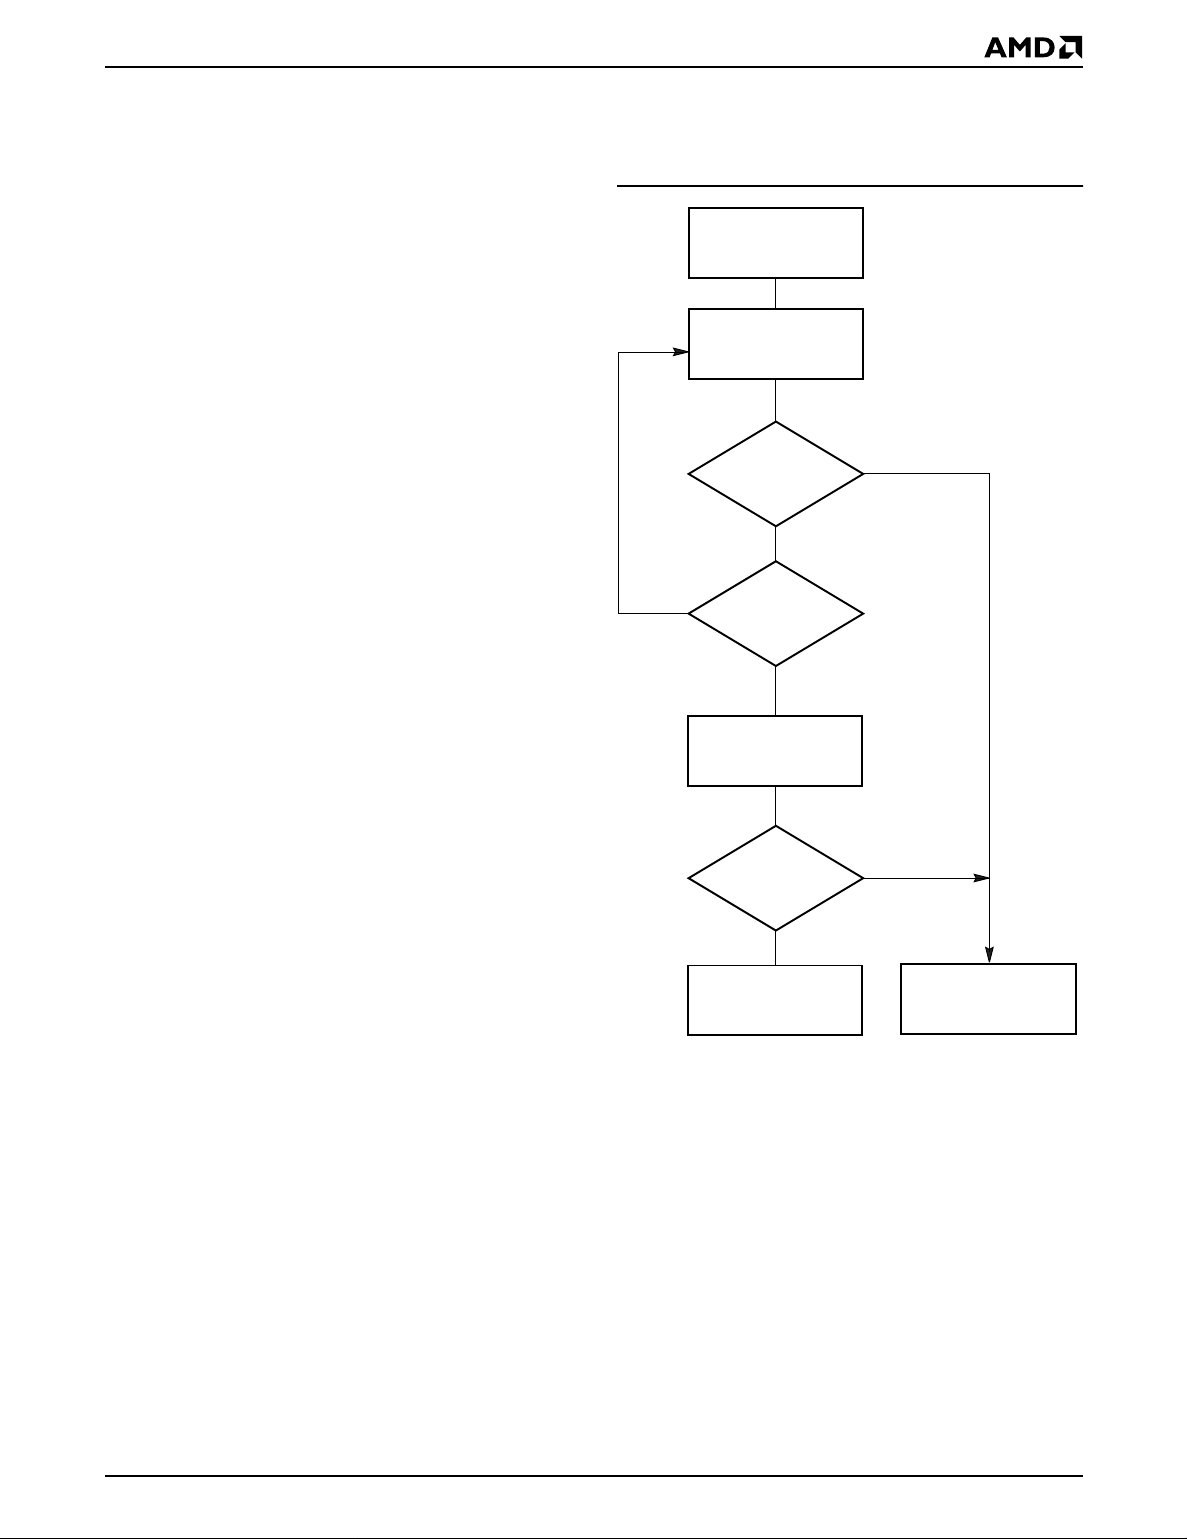
WRITE OPERATION STATUS
The device provides several bits to determine the
status of a write operation: DQ2, DQ3, DQ5, DQ6,
DQ7, and RY/BY#. Table 1 and the following subsections describe the func tions of these bits. DQ7, RY/
BY#, and DQ6 each offer a method for determining
whether a program or erase oper ation is c omplete or in
progress. These three bits are discussed first.
Table 1 shows the outputs for Data# Polling on DQ7.
Figure 4 shows the Data# Polling algorithm.
START
DQ7: Data# Polling
The Data# Polling bit, DQ7, indicates to the host
system whether an Embedded Algorithm is in progress
or completed, or wh ether the device is in Erase Suspend. Data# Polling is valid after the rising edge of the
final WE# pulse in the program or erase command
sequence.
During the Em bedded Program algor ithm, the device
outputs on DQ7 the complement of the datum programmed to DQ7. Thi s DQ7 status also appl ies to
programming during Erase Suspend. When the
Embedded Program algorithm is complete, the device
outputs the datum programmed to DQ7. The system
must provide the program address to read valid status
information on DQ7. If a program address f alls within a
protected sector, Data# Polling on DQ7 is active for
approximately 2 µs, then the device returns to reading
array data.
During the Embedded Erase algorithm, Data# Polling
produces a “0” on DQ7. When the Embedded Erase
algorithm is complete, or if the device enters the Erase
Suspend mode, Data# Polling produces a “1” on DQ7.
This is analogous to the complement/true datum output
described for the Embedded Program algorithm: the
erase function changes all the bits in a sector to “1”;
prior to this, the device outputs the “complement,” o r
“0.” The system must provide an address within any of
the sectors selected for erasure to read valid status
information on DQ7.
No
Read DQ7–DQ0
Addr = VA
DQ7 = Data?
No
DQ5 = 1?
Yes
Read DQ7–DQ0
Addr = VA
DQ7 = Data?
No
FAIL
Yes
Yes
PASS
After an erase command sequence is written, if all
sectors selected for erasing are protected, Data#
Polling on DQ7 is active for approximately 100 µs, then
the device returns to reading array data. If not all
selected sectors are protected, the Embedd ed Erase
algorithm erases the unprotected sectors, and ignores
the selected sectors that are protected.
When the system detects DQ7 has changed from the
complement to true data, it can read va lid data at DQ7–
DQ0 on the
following
read cycles. This is because DQ7
may change asynchronously with DQ0–DQ6 while
Output Enable (OE#) is assert ed low. The Data#
Polling Timings (During Embedded Algorithms) figure
in the “AC Characteristics” section illustrates this.
Am29F200B 17
Notes:
1. VA = Valid address for programming. During a sector
erase operation, a valid address is an address within any
sector selected for erasure. During chip erase, a valid
address is any non-protected sector address.
2. DQ7 should be rechecked even if DQ5 = “1” because
DQ7 may change simultaneously with DQ5.
21526B-8
Figure 4. Data# Polling Algorithm
Page 18
RY/BY#: Ready/Busy#
The RY/BY# is a dedicated, open-drain output pin that
indicates whether an Embedded Algorithm is in
progress or complete. The RY/BY# status is valid after
the rising edge of the final WE# pulse in the command
sequence. Since RY/BY# is an open-drain output,
several RY/BY# pins can be tied together in parallel
with a pull-up resistor to V
If the output is low (Busy ), the de vice is activ ely er asing
or programming. (T his includes programming in the
Erase Suspend mode.) If th e output is high (Ready) ,
the device is ready to read array data (including during
the Erase Suspend mode), or is in the standby mode.
Table 1 shows the outputs for RY/BY#. The timing diagrams for read, reset, program, and erase shows the
relationship of RY/BY# to other signals.
CC
.
DQ6: Toggle Bit I
Toggle Bi t I on DQ6 indicates w hether an Embedded
Program or Erase algorithm is in progress or complete,
or whether the device has entered the Erase Suspend
mode. Toggle Bit I may be read at any address, and is
valid after the rising edge of the final WE# pulse in the
command sequence (prior to the program or erase
operation), and during the sector erase time-out.
The Write Operation Status table shows the outputs for
Toggle Bit I on DQ6. Refer to Figure 5 for the toggle bit
algorithm, and to the Toggle Bit Timings figure in the
“AC Characteristics” section for the timing diagram.
The DQ2 vs. DQ6 figure shows the differences
between DQ2 and DQ6 in graphical form. See also the
subsection on “DQ2: Toggle Bit II”.
DQ2: Toggle Bit II
The “Toggle Bit II” on DQ2, when used with DQ6, indicates whether a par ticular sect or is actively erasing
(that is, the Embedded Erase algo rithm is in pro gress),
or whether that sector is erase-suspended. Toggle Bit
II is valid after the rising edge of t he final WE# pulse in
the command sequence.
DQ2 toggles w hen the system reads at addresses
within those sector s that have been selected for erasure. (The system may use either OE# or CE# to
control the read cycles.) But DQ2 cannot distinguish
whether the sector is actively erasing or is erase-suspended. DQ6, by comparison, indicates whether the
device is actively erasing, or is in Erase Suspend, but
cannot distinguish which sectors are selected for erasure. Thus, both status bits are required for sector and
mode information. Refer to Table 1 to compare output s
for DQ2 and DQ6.
During an Embedded Program or Erase algorithm
operation, successive read cycles to any address
cause DQ6 to toggle. (The system may us e either OE#
or CE# to control the read cycles.) When the operation
is complete, DQ6 stops toggling.
After an erase command sequence is written, if all
sectors selected for er asing are protected, DQ6 toggles
for appro ximately 100 µs, then returns to reading array
data. If not all selected sectors are protected, the
Embedded Erase algorithm erases the unprotected
sectors, and ignores the selected sectors that are
protected.
The system can use DQ6 and DQ2 together to determine whether a sector is actively erasing or is erasesuspended. When the device is activ ely erasing (that is ,
the Embedded Erase algorithm is in progress), DQ6
toggles. When the device enters the Erase Suspend
mode, DQ6 stops toggling. However, the system must
also use DQ2 to determine which sectors are erasing
or erase-suspended. Alternatively, the system can use
DQ7 (see the subsection on “DQ7: Data# Polling”).
If a program address falls within a pro tected sector,
DQ6 toggles for approximately 2 µs after the program
command sequence is written, then returns to reading
array data.
DQ6 also toggles during the erase-suspend-program
mode, and stops toggling once the Embedded
Program algorithm is complete.
Figure 5 shows the toggle bit algorithm in flowchar t
form, and the section “DQ2: Toggle Bit II” explains the
algorithm. See also the “DQ6: Toggle Bit I” subsection.
Refer to the Toggle Bit Timings figure for the toggle bit
timing diagram. The DQ2 vs. DQ6 figure shows t he differences between DQ2 and DQ6 in graphical f orm.
Reading Toggle Bits DQ6/DQ2
Refer to Figure 5 for the following discussion. Whe never the system initially begins readin g toggle bit
status, it must read DQ7–DQ0 at least t wice in a row to
determine whether a toggle bit is toggling. Typically, a
system would note and store the value of the t oggle bit
after the first read. After the second read, the system
would compare the new value of the toggle bit with the
first. If the toggle bit is not toggling, the device has completed the program or eras e operation. The system can
read array data on DQ7–DQ0 o n the following read
cycle.
However, if after the initial two read cycles, the system
determines that the toggle bit is still toggli ng, the
system also should note whether the value of DQ5 is
high (see the section on DQ5). If it is, the system
should then determine again whether the toggle bit is
toggling, since the toggle bit may have stopped toggling just as DQ5 went high. If the toggle bit is no longer
toggling, the device has successfully comp leted the
program or erase operation. If it is still toggling, the
device did not complete the oper ation successfully, and
18 Am29F200B
Page 19
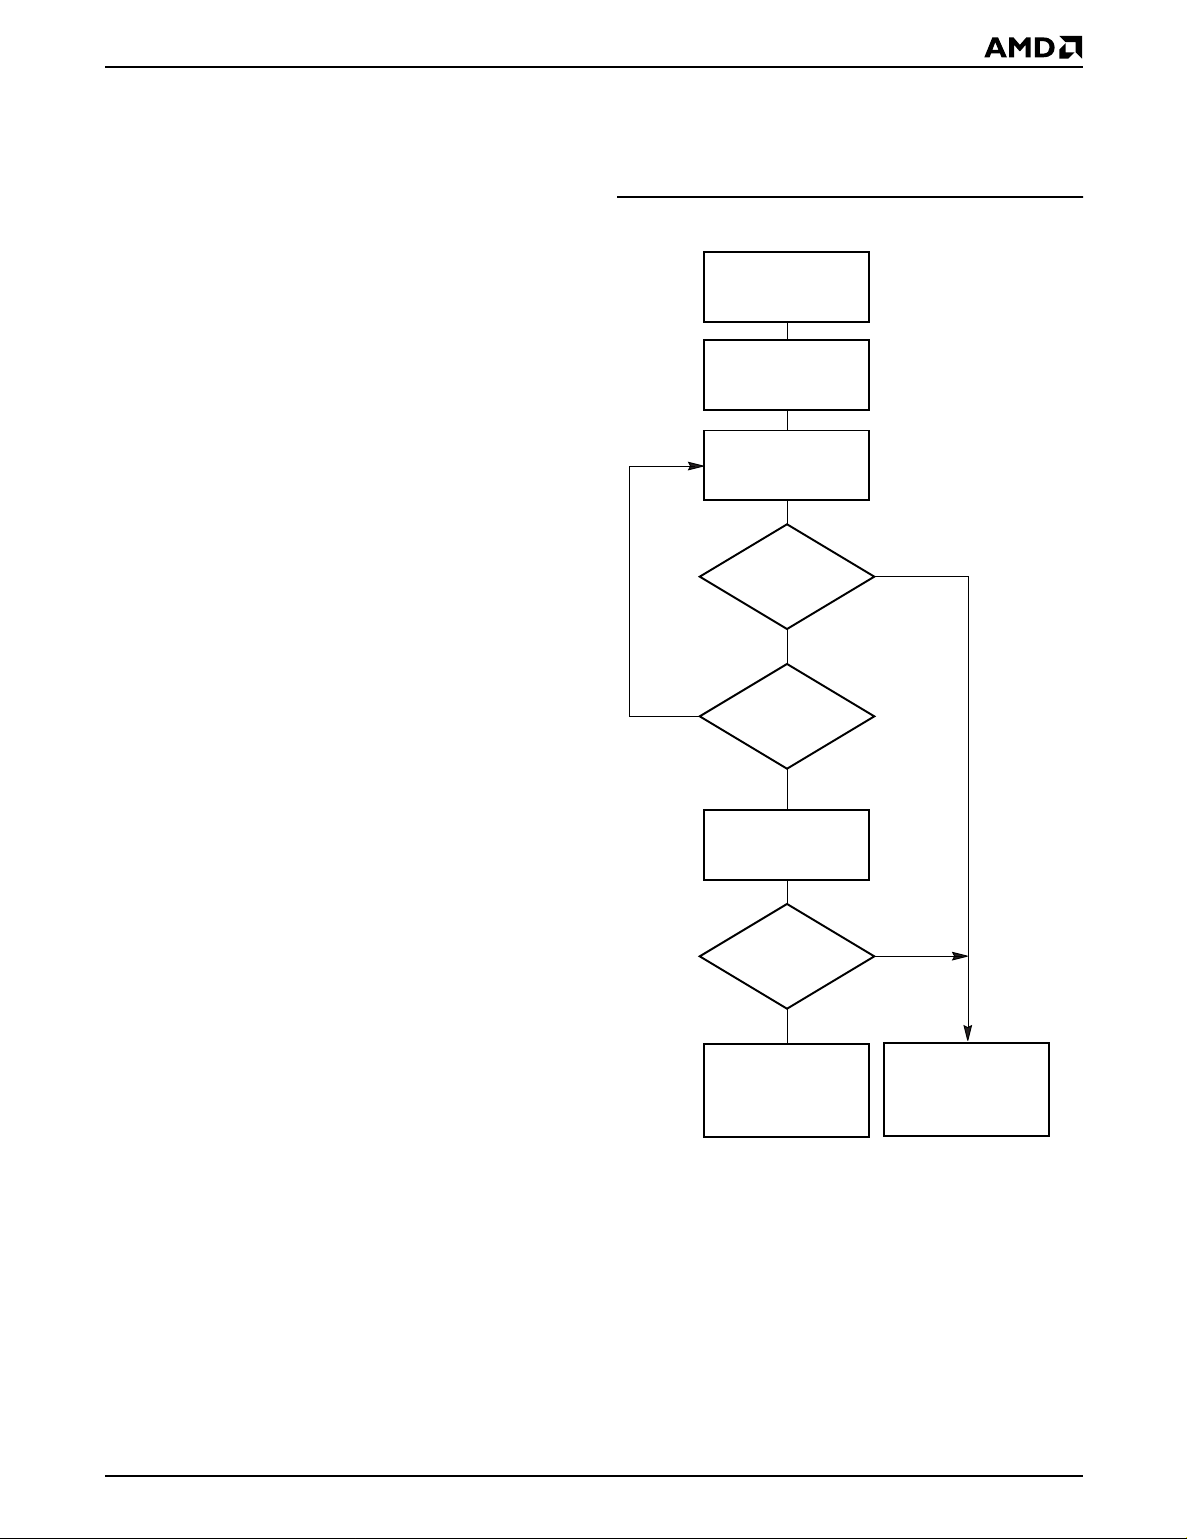
the system must write the reset command to return to
reading array data.
The remaining scenario is that the system initially
determines that the toggle bit is toggling and DQ5 has
not gone high. The system may contin ue to monitor the
toggle bit and DQ5 through successive read cy cles,
determining the status as described in the previous
paragraph. Alternatively, it may choose to perform
other system tasks. In this case, the system must start
at the beginning of the algorithm when it returns to
determine the status of the operation (top of Figure 5).
DQ5: Exceeded Timing Limits
DQ5 indicates whether the program or erase time has
exceeded a specified internal pulse count limit. Under
these conditions DQ5 produces a “1.” This is a failure
condition that indicates the prog ram or er ase cycle was
not successfully completed.
of DQ3 prior to and following each subsequent sector
erase command. If DQ3 is high on the second status
check, the last command might not have been
accepted. Table 1 shows the outputs for DQ3.
START
Read DQ7–DQ0
Read DQ7–DQ0
(Note 1)
The DQ5 failure condition may appear if the system
tries to program a “1” to a location that i s previously programmed to “0.” Only an era se operation can change
a “0” back to a “1.” Under this condition, the device
halts the operation, and when the operation has
exceeded the timing limits, DQ5 produces a “1.”
Under both these conditions, t he system must issue the
reset command to return the device to reading array
data.
DQ3: Sector Erase Timer
After writing a sector erase comm and sequence, the
system may read DQ3 to determine whether or not an
erase operation has begun. (The sector erase timer
does not apply to the chip erase command.) If additional sectors are selected for erasure, the entire timeout also applies after each additional sector erase command. When the time-out is com plete, DQ3 switches
from “0” to “1.” The system may ignore DQ3 if the
system can guarantee that the ti me between add itional
sector erase commands will always be less than 50 µs.
See also the “Sector Erase Command Sequence”
section.
After the sector erase command sequence is written,
the system should read the status on DQ7 (Data#
Polling) or DQ6 (Toggle Bit I) to ensure the device has
accepted the command sequence, and then read DQ3.
If DQ3 is “1”, the internally controlled erase cycle has
begun; all further commands (other than Erase Suspend) are ignored until the er ase operation is complete .
If DQ3 is “0”, the device will accept additional sector
erase commands. To ensure the comm and has been
accepted, the system software should ch eck the s tatus
Toggle Bit
= Toggle?
Yes
No
Notes:
1. Read toggle bit twice to determine whether or not it is
toggling. See text.
2. Recheck toggle bit because it may stop toggling as DQ5
changes to “1”. See text.
DQ5 = 1?
Yes
Read DQ7–DQ0
Twice
Toggle Bit
= Toggle?
Yes
Program/Erase
Operation Not
Complete, Write
Reset Command
No
(Notes
1, 2)
No
Program/Erase
Operation Complete
21526B-9
Figure 5. Toggle Bit Algorithm
Am29F200B 19
Page 20
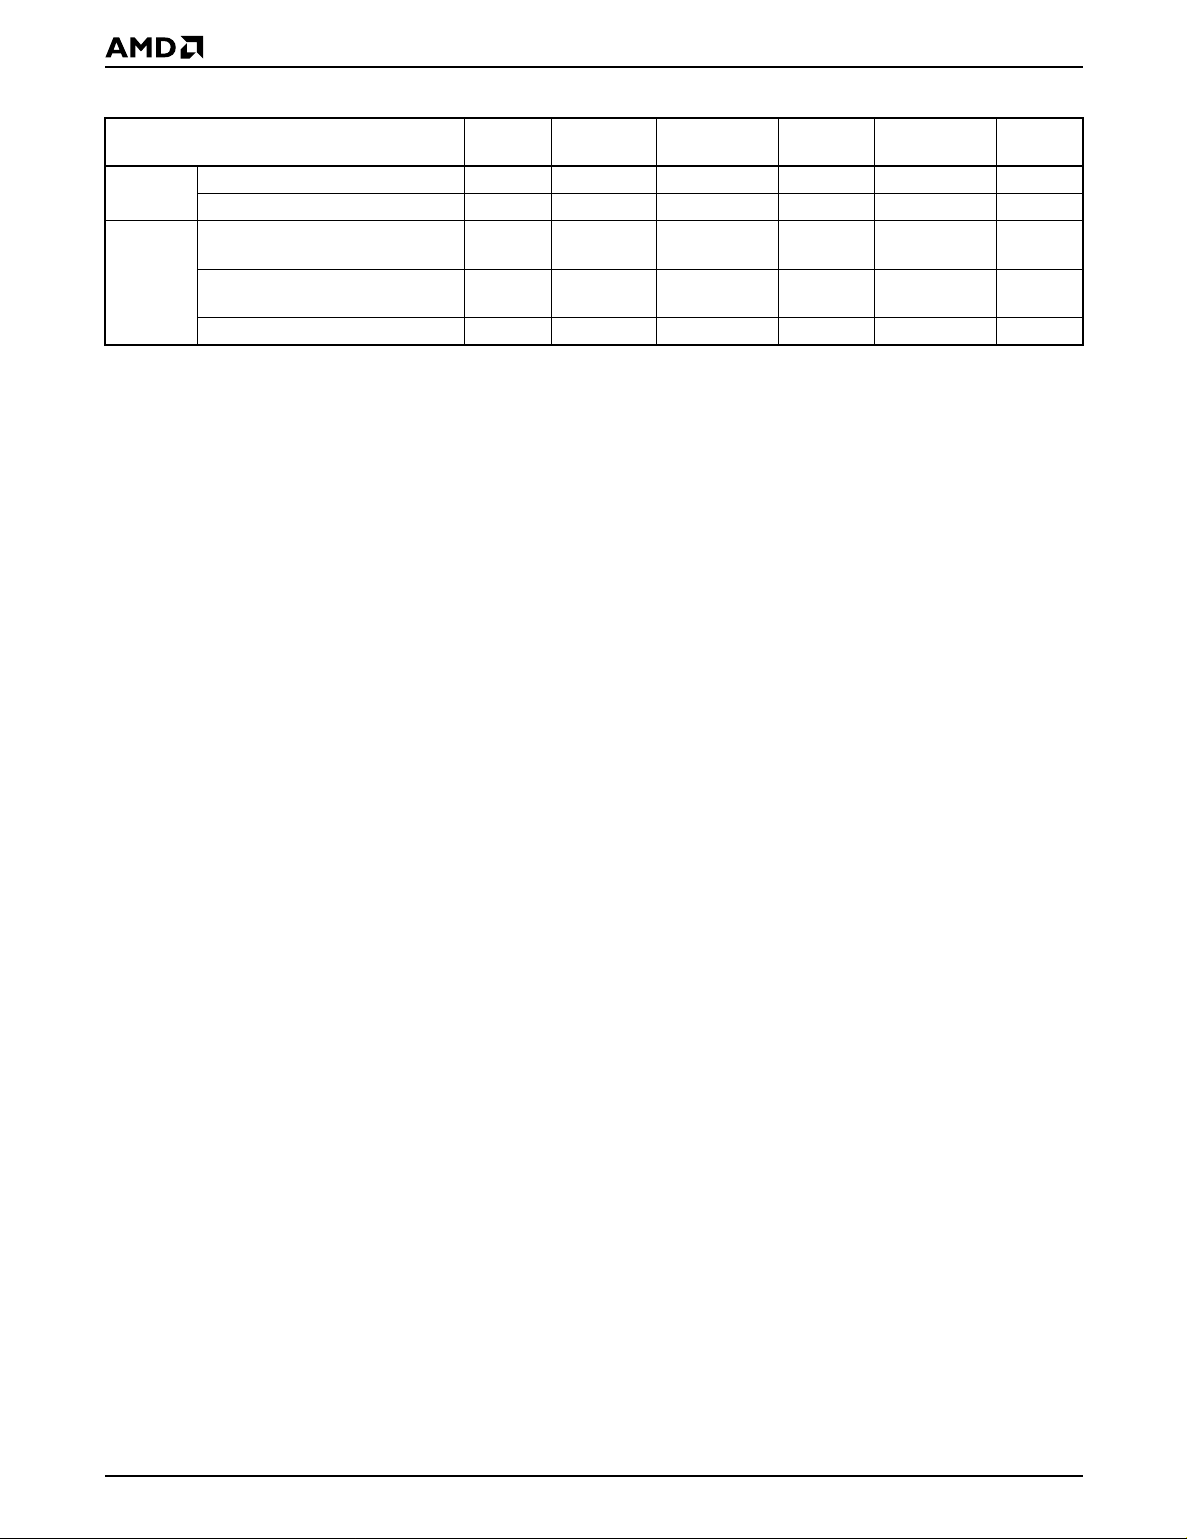
Table 1. Write Operation Status
DQ7
Standard
Mode
Erase
Suspend
Mode
Operation
Embedded Program Algorithm DQ7# Toggle 0 N/A No toggle 0
Embedded Erase Algorithm 0 Toggle 0 1 Toggle 0
Reading within Erase
Suspended Sector
Reading within Non-Erase
Suspended Sector
Erase-Suspend-Program DQ7# Toggle 0 N/A N/A 0
(Note 1) DQ6
1 No toggle 0 N/A Toggle 1
Data Data Data Data Data 1
Notes:
1. DQ7 and DQ2 require a valid address when reading status information. Refer to the appropriate subsection for further details.
2. DQ5 switches to ‘1’ when an Embedded Program or Embedded Erase operation has exceeded the maximum timing limits.
See “DQ5: Exceeded Timing Limits” for more information.
DQ5
(Note 2) DQ3
DQ2
(Note 1) RY/BY#
20 Am29F200B
Page 21
ABSOLUTE MAXIMUM RATINGS
Storage Temperature
Plastic Packages . . . . . . . . . . . . . . . –65°C to +150°C
Ambient Temperature
with Power Applied. . . . . . . . . . . . . . –55°C to +125°C
Voltage with Respect to Ground
(Note 1) . . . . . . . . . . . . . . . .–2.0 V to +7.0 V
V
CC
A9, OE#, and
RESET# (Note 2). . . . . . . . . . . .–2.0 V to +12.5 V
All other pins (Note 1) . . . . . . . . .–0.5 V to +7.0 V
Output Short Circuit Current (Note 3) . . . . . . 200 mA
Notes:
1. Minimum DC voltage on input or I/O pins is –0.5 V. During
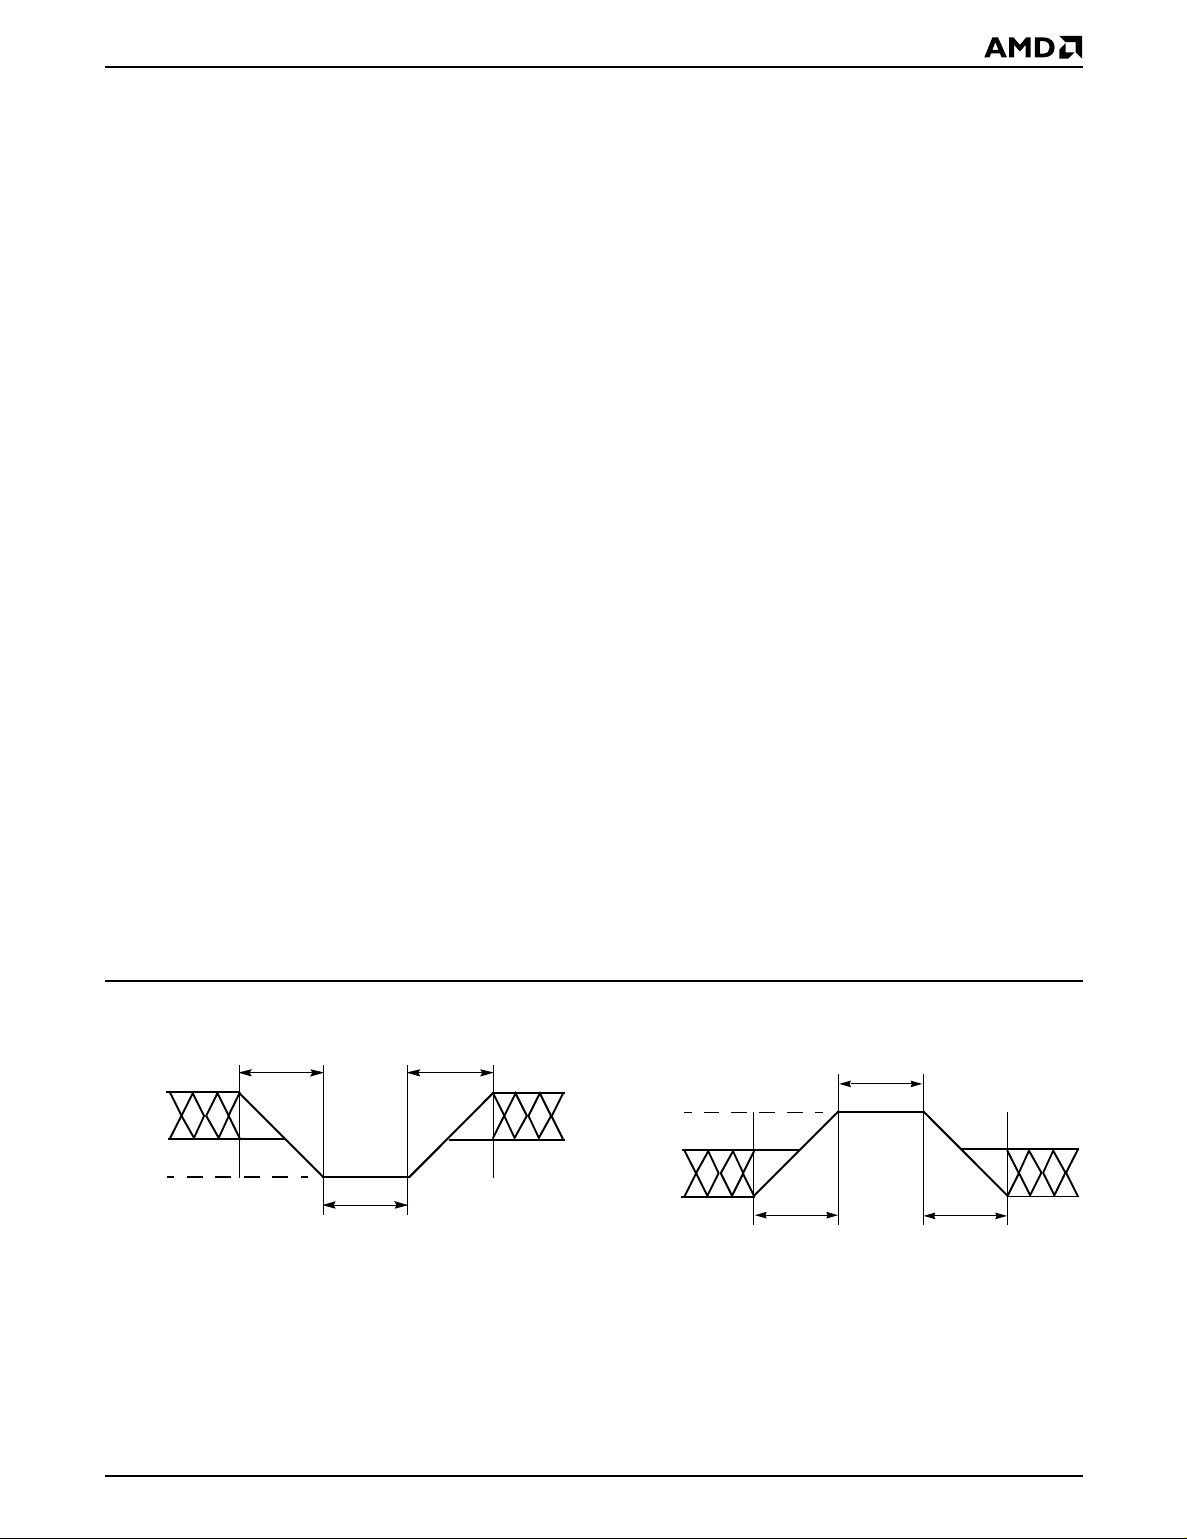
voltage transitions, i nput or I/O pins may overshoot V
to –2.0 V for periods of up to 20 ns. See Figure 6.
Maximum DC voltage on input or I/O pin s is V
During voltage transitions, input or I/O pins may overshoot
to V
+2.0 V for periods up to 20 ns. See Figure 7.
CC
2. Minimum DC input voltage on pins A9, OE#, and RESET#
is –0.5 V. During voltage transitions, A9, OE#, and
RESET# may overshoot V
to 20 ns. See Figure 6. Maximum DC input voltage on pin
A9 is +12.5 V which may overshoot to +13.5 V for periods
up to 20 ns.
3. No more than on e output may be shor te d to ground at a
time. Duration of the short circuit should not be greater
than one second.
Note: Stresses above those listed under “Absolute Maximum
Ratings” may cause permanent damage to the device. This
is a stress rating only; functional operation of the device at
these or any other conditions above those indicated in the operational sections of this data sheet is not implied. Exposure
of the device to absolute maximum rating conditions for extended periods may affect device reliability.
to –2.0 V for periods of up
SS
CC
SS
+0.5 V.
OPERATING RANGES
Commercial (C) Devices
Ambient Temperature (T
Industrial (I) Devices
Ambient Temperature (T
Extended (E) Devices
Ambient Temperature (T
VCC Supply Voltages
for ± 5% devices . . . . . . . . . . +4.75 V to +5.25 V
V
CC
for± 10% devices. . . . . . . . . . . . +4.5 V to +5.5 V
V
CC
Note: Operating ranges define those limits between which
the functionality of the device is guaranteed.
) . . . . . . . . . . .0°C to +70°C
A
) . . . . . . . . .–40°C to +85°C
A
) . . . . . . . .–55°C to +125°C
A
20 ns
+0.8 V
–0.5 V
–2.0 V
20 ns
20 ns
Figure 6. Maximum Negative Overshoot
Waveform
20 ns
V
CC
+2.0 V
V
CC
+0.5 V
2.0 V
20 ns
21526B-10
20 ns
Figure 7. Maximum Posi tive Overshoot
Waveform
Am29F200B 21
21526B-11
Page 22
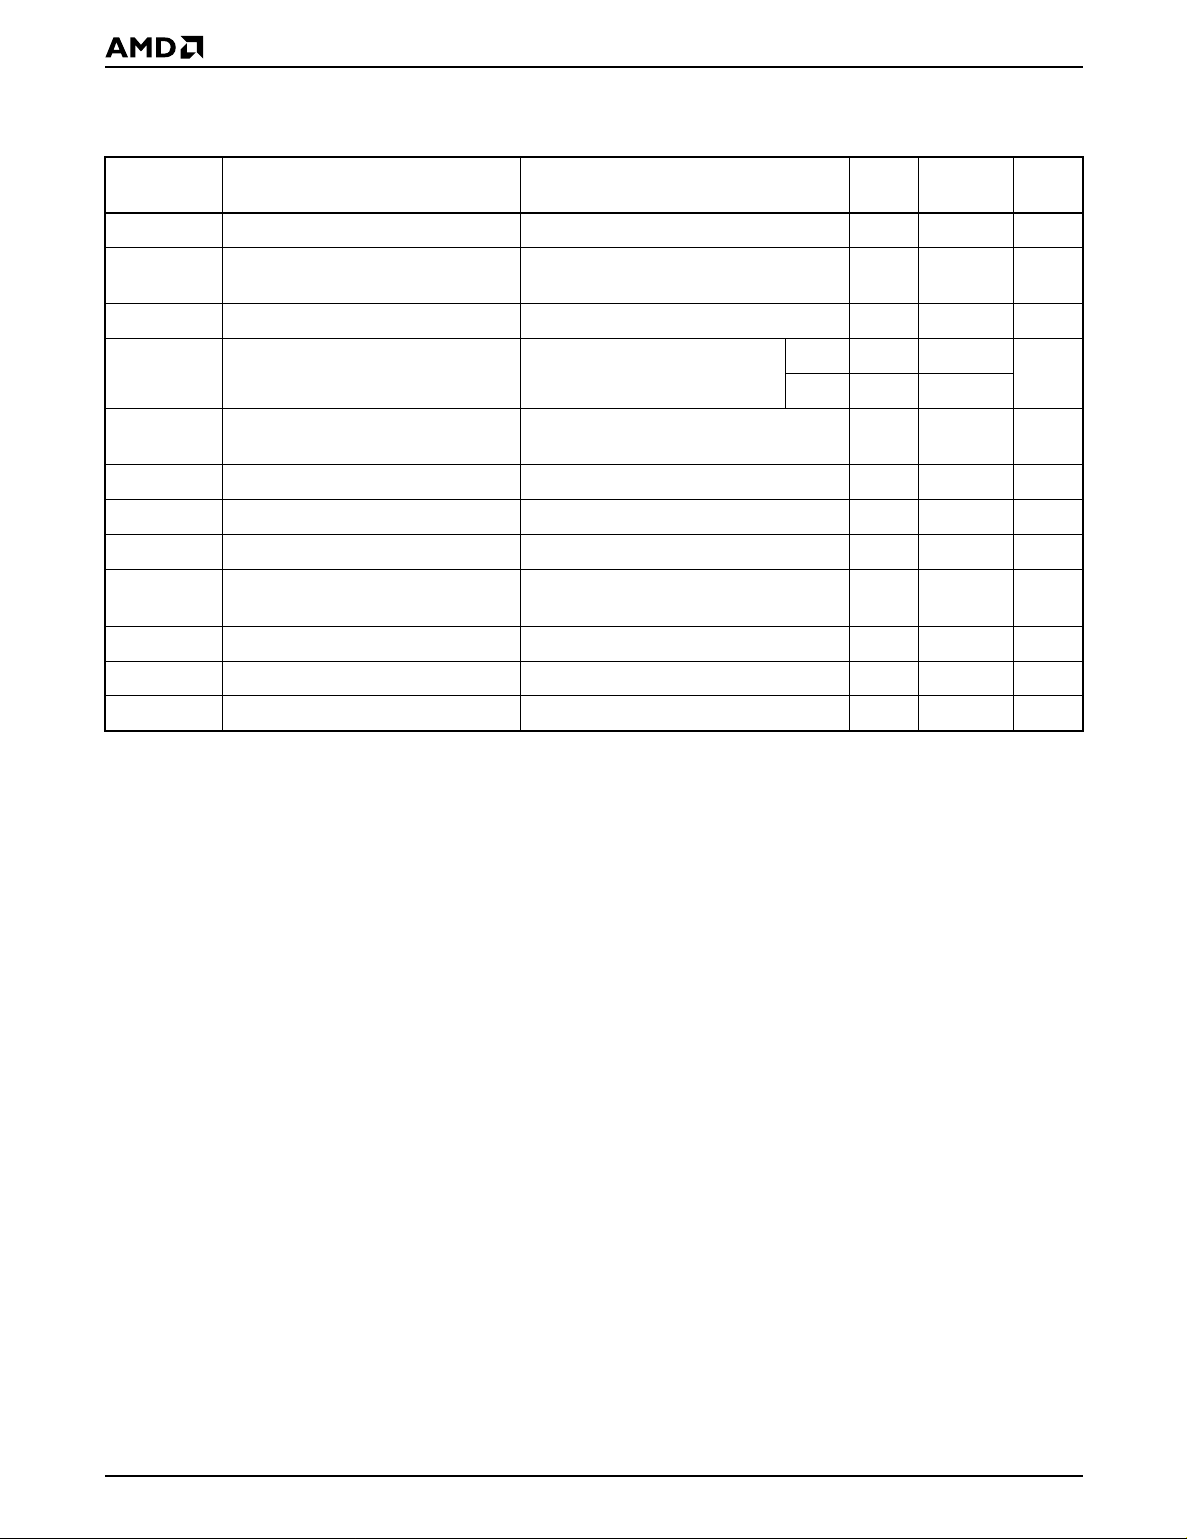
DC CHARACTERISTICS
TTL/NMOS Compatible
Parameter
Symbol Parameter Descri ptio n Test Conditions Min M ax Unit
V
I
I
I
CC1
I
CC2
I
CC3
V
V
V
V
V
I
LI
LIT
LO
IL
IH
ID
OL
OH
LKO
Input Load Current VIN = VSS to VCC, VCC = VCC Max ±1.0 µA
A9, OE#, RESET# Input Load
Current
Output Leakage Current V
VCC = VCC Max,
A9, OE
OUT
VCC Active Read Current (Notes 1, 2) CE# = VIL, OE# = V
VCC Active Program/Erase Current
(Notes 2, 3, 4)
CE
# = V
VCC Standby Current (Note 2) VCC = VCC Max, CE# = VIH, OE# = V
Input Low Voltage –0.5 0.8 V
Input High Voltage 2.0 VCC + 0.5 V
V oltage for Autoselect and Temporary
Sector Unprotect
V
CC
Output Low Voltage IOL = 5.8 mA, VCC = VCC Min 0.45 V
Output High Voltage IOH = –2.5 mA, VCC = VCC Min 2.4 V
Low VCC Lock-Out Voltage 3.2 4.2 V
Notes:
1. The I
2. Maximum I
3. I
current is typically less than 2 mA/MHz, with OE# at VIH.
CC
specifications are tested with VCC = V
CC
active while Embedded Program or Erase Algorithm is in progress.
CC
CCmax
4. Not 100% tested.
#, RESET# = 12.5 V
50 µA
= VSS to VCC, VCC = VCC Max ±1.0 µA
Byte 40
mA
, OE# = V
IL
IH
IH
Word 50
60 mA
IH
1.0 mA
= 5.0 V 11.5 12.5 V
.
22 Am29F200B
Page 23
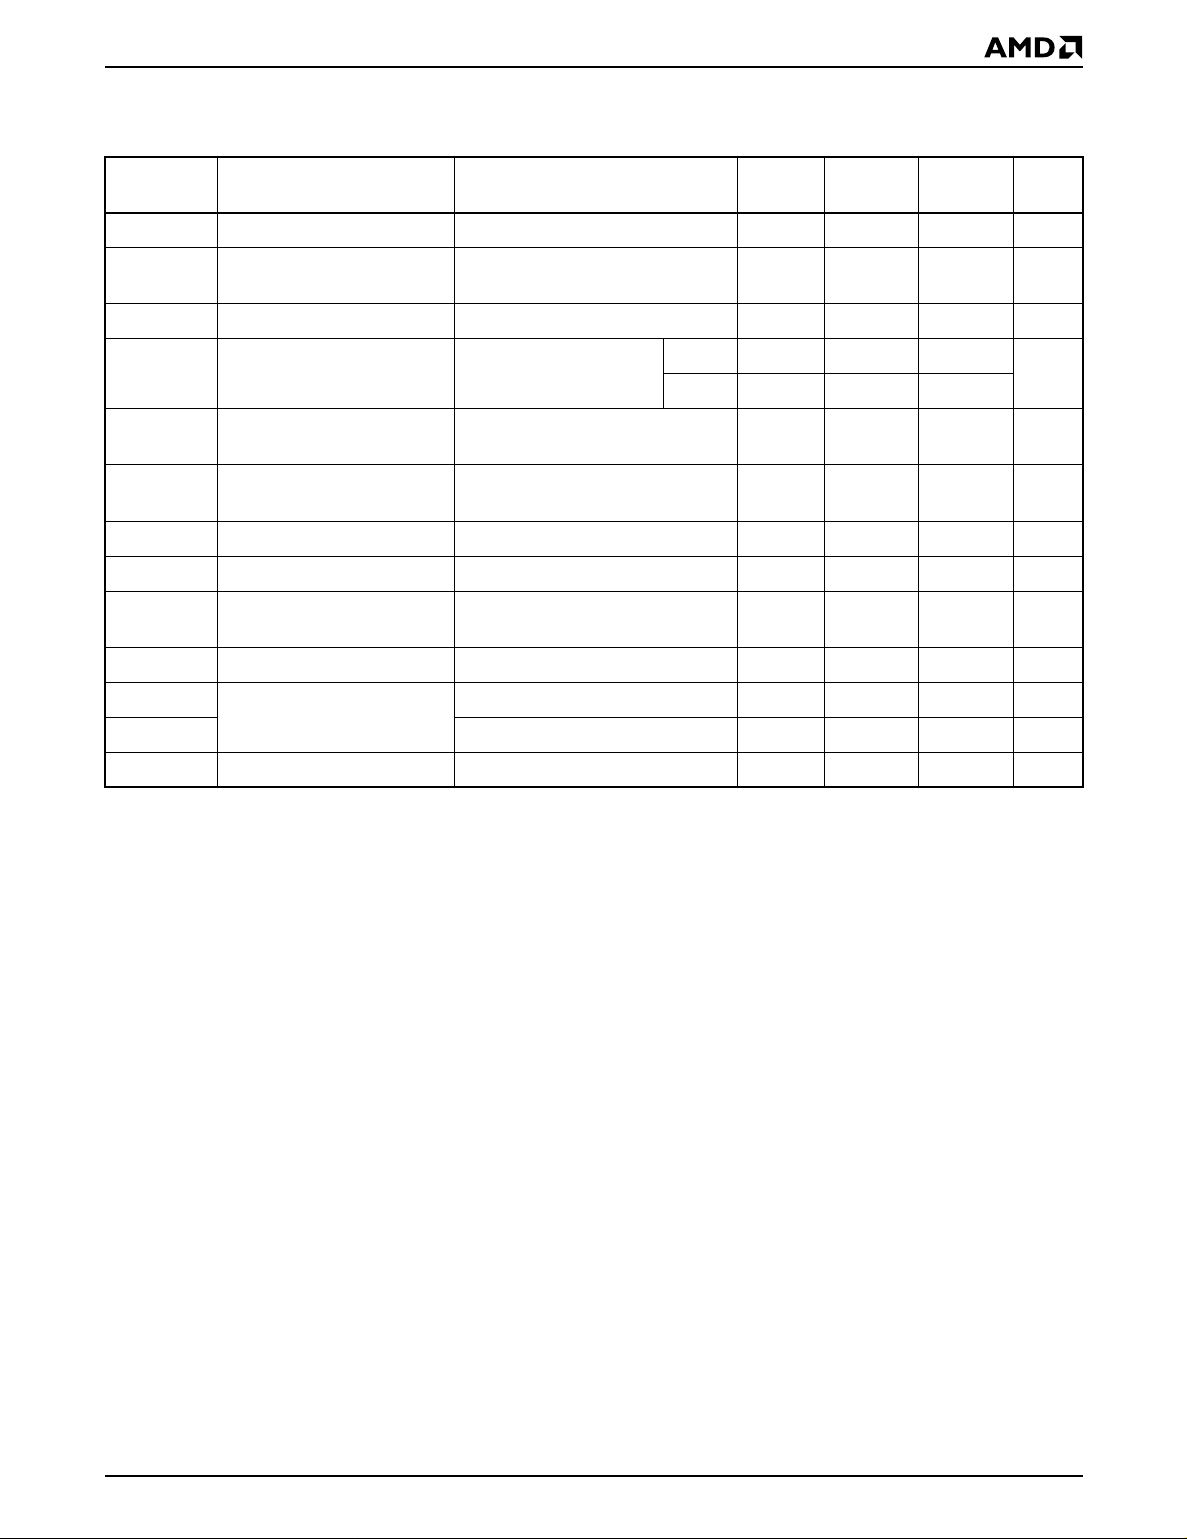
DC CHARACTERISTICS (Continued)
CMOS Compatible
Parameter
Symbol Parameter Description Test Conditions Min Typ Max Unit
I
LI
I
LIT
I
LO
I
CC1
I
CC2
I
CC3
V
IL
V
IH
V
ID
V
OL
V
OH1
V
OH2
V
LKO
Input Load Current VIN = VSS to VCC, VCC = VCC Max ±1.0 µA
A9, OE#, RESET# Input
Load Current
Output Leakage Current V
VCC Active Read Current
(Notes 1, 2)
VCC Active Program/Erase
Current (Notes 2, 3, 4)
VCC Standby Current
Note (Note 5)
VCC = VCC Max;
A9, OE
#, RESET# = 12.5 V
= VSS to VCC, VCC = VCC Max ±1.0 µA
OUT
CE# = VIL, OE# = V
CE
# = V
, OE# = V
IL
CE# = VCC ± 0.5 V, OE# = V
Input Low Voltage –0.5 0.8 V
Input High Voltage 0.7 x V
Voltage for Autoselect and
Temporary Sector Unprotect
V
= 5.0 V 11.5 12.5 V
CC
Output Low Voltage IOL = 5.8 mA, VCC = VCC Min 0.45 V
IOH = –2.5 mA, VCC = VCC Min 0.85 V
Output Low Voltage
IOH = –100 µA, VCC = VCC Min VCC – 0.4 V
Low VCC Lock-Out Voltage 3.2 4.2 V
Notes:
1. The I
2. Maximum I
3. I
current listed is typically less than 2 mA/MHz, with OE# at VIH.
CC
specifications are tested with VCC = V
CC
active while Embedded Program or Erase Algorithm is in progress.
CC
CCmax
4. Not 100% tested.
5. I
for extended temperature is 20 µA max (>+85
CC3
°
C).
50 µA
Byte 20 40
IH
Word 28 50
IH
IH
CC
CC
30 50 mA
15µA
VCC + 0.3 V
mA
V
.
Am29F200B 23
Page 24
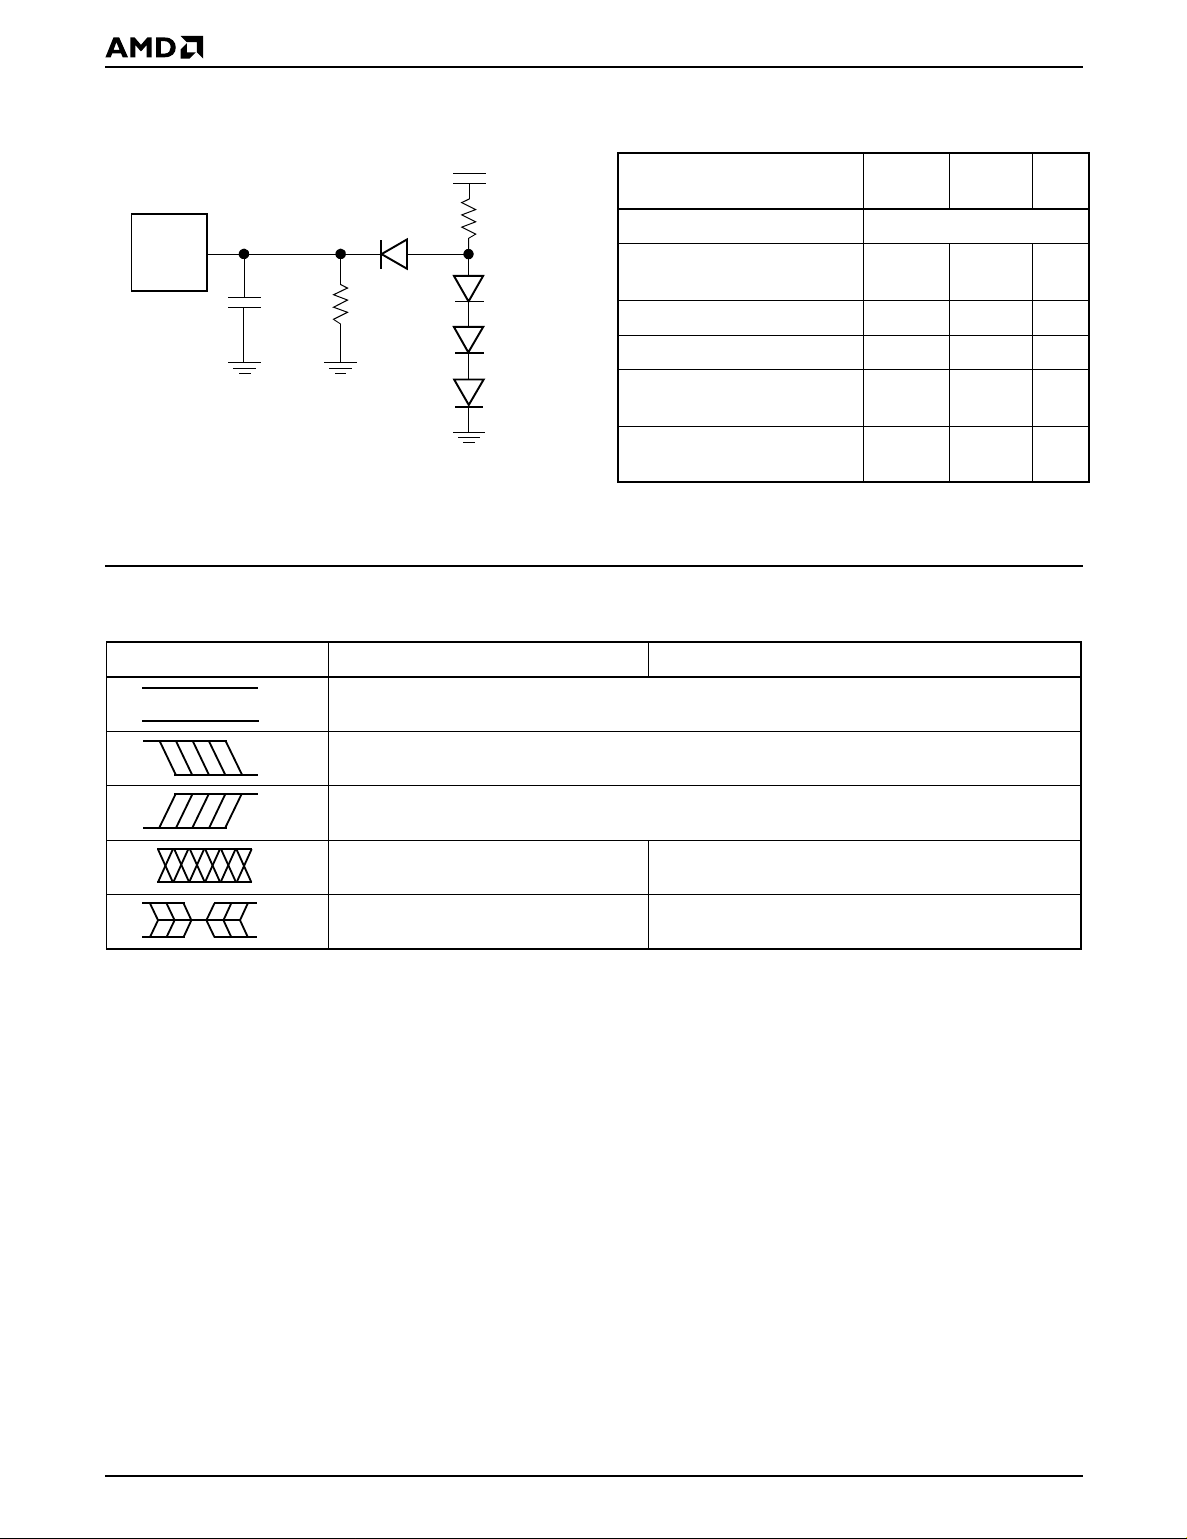
TEST CONDITIONS
Device
Under
Test
C
L
6.2 kΩ
5.0
2.7 kΩ
Table 6. Test Specifications
-45, -50,
Test Condition
Output Load 1 TTL gate
Output Load Capacitance, C
(including jig capacitance)
Input Rise and Fall Times 5 20 ns
Input Pulse Levels 0.0–3.0 0.45–2.4 V
-55
L
30 100 pF
All
others Unit
Note:
Diodes are IN3064 or equivalents.
Figure 8. Test Setup
KEY TO SWITCHING WAVEFORMS
WAVEFORM INPUTS OUTPUTS
Don’t Care, Any Change Permitted Changing, State Unknown
Does Not Apply Center Line is High Impedance State (High Z)
21526B-12
Input timing measurement
reference levels
Output timing measurement
reference levels
Steady
Changing from H to L
Changing from L to H
1.5 0.8, 2.0 V
1.5 0.8, 2.0 V
24 Am29F200B
KS000010-PAL
Page 25
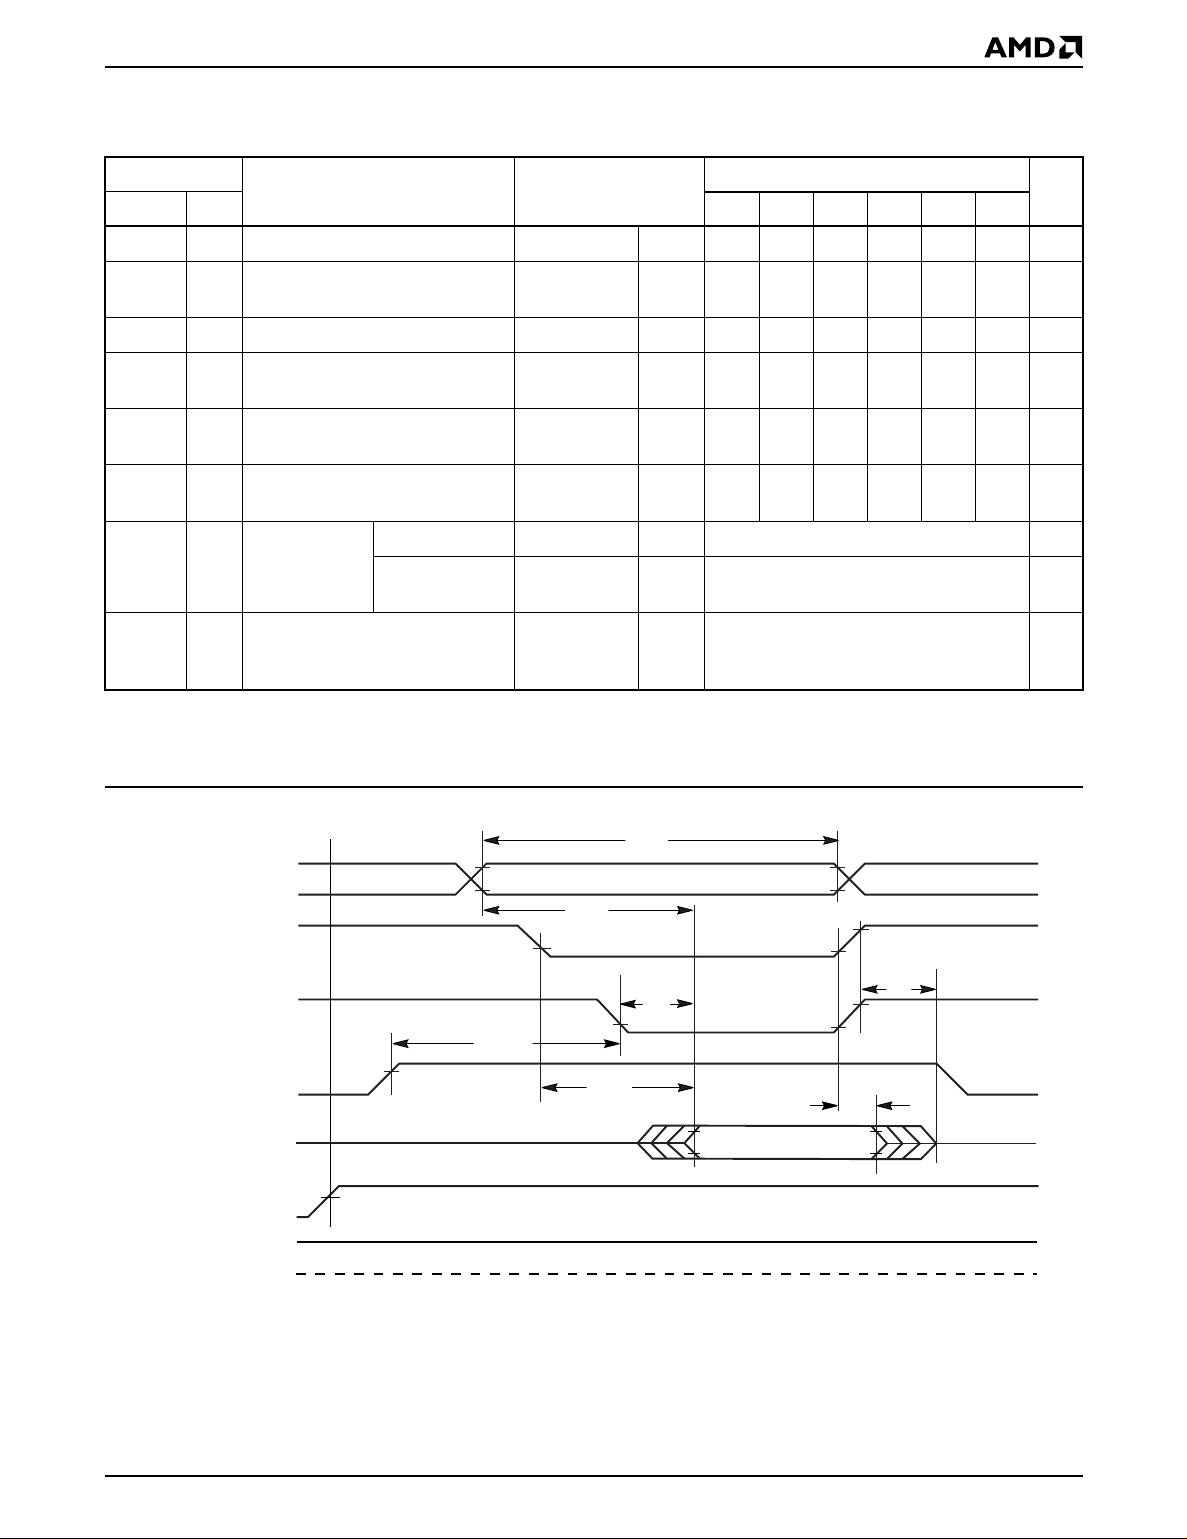
AC CHARACTERISTICS
Read Operations
Parameter
JEDEC Std Test Setup -45 -50 -55 -70 -90 -120 Unit
t
AVAV
t
AVQVtACC
t
ELQVtCE
t
GLQVtOE
t
EHQZtDF
t
GHQZtDF
Description
t
Read Cycle Time (Note 1) Min 45 50 55 70 90 120 ns
RC
Address to Output Delay
Chip Enable to Output Delay OE# = V
Output Enable to Output Delay
(Note 1)
Chip Enable to Output High Z
(Note 1)
Output Enable to Output High Z
(Note 1)
Output Enable
Hold Time
t
OEH
(Note 1)
Read Min 0 ns
Toggle and
Data# Polling
CE# = V
OE# = V
IL
Max4550557090120ns
IL
Max4550557090120ns
IL
Max303030303550ns
Max202020202030ns
Max202020202030ns
Min 10 ns
Speed Options
Output Hold Time From
t
AXQXtOH
Addresses, CE# or OE#,
Min 0 ns
Whichever Occurs First (Note 1)
Notes:
1. Not 100% tested.
2. See Figure 8 and Table 6 for test specifications
Addresses
CE#
OE#
WE#
Outputs
RESET#
RY/BY#
0 V
t
RC
Addresses Stable
t
ACC
t
OE
t
OEH
t
CE
HIGH Z
Output Valid
Figure 9. Read Operations Timings
t
OH
t
DF
HIGH Z
Am29F200B 25
Page 26
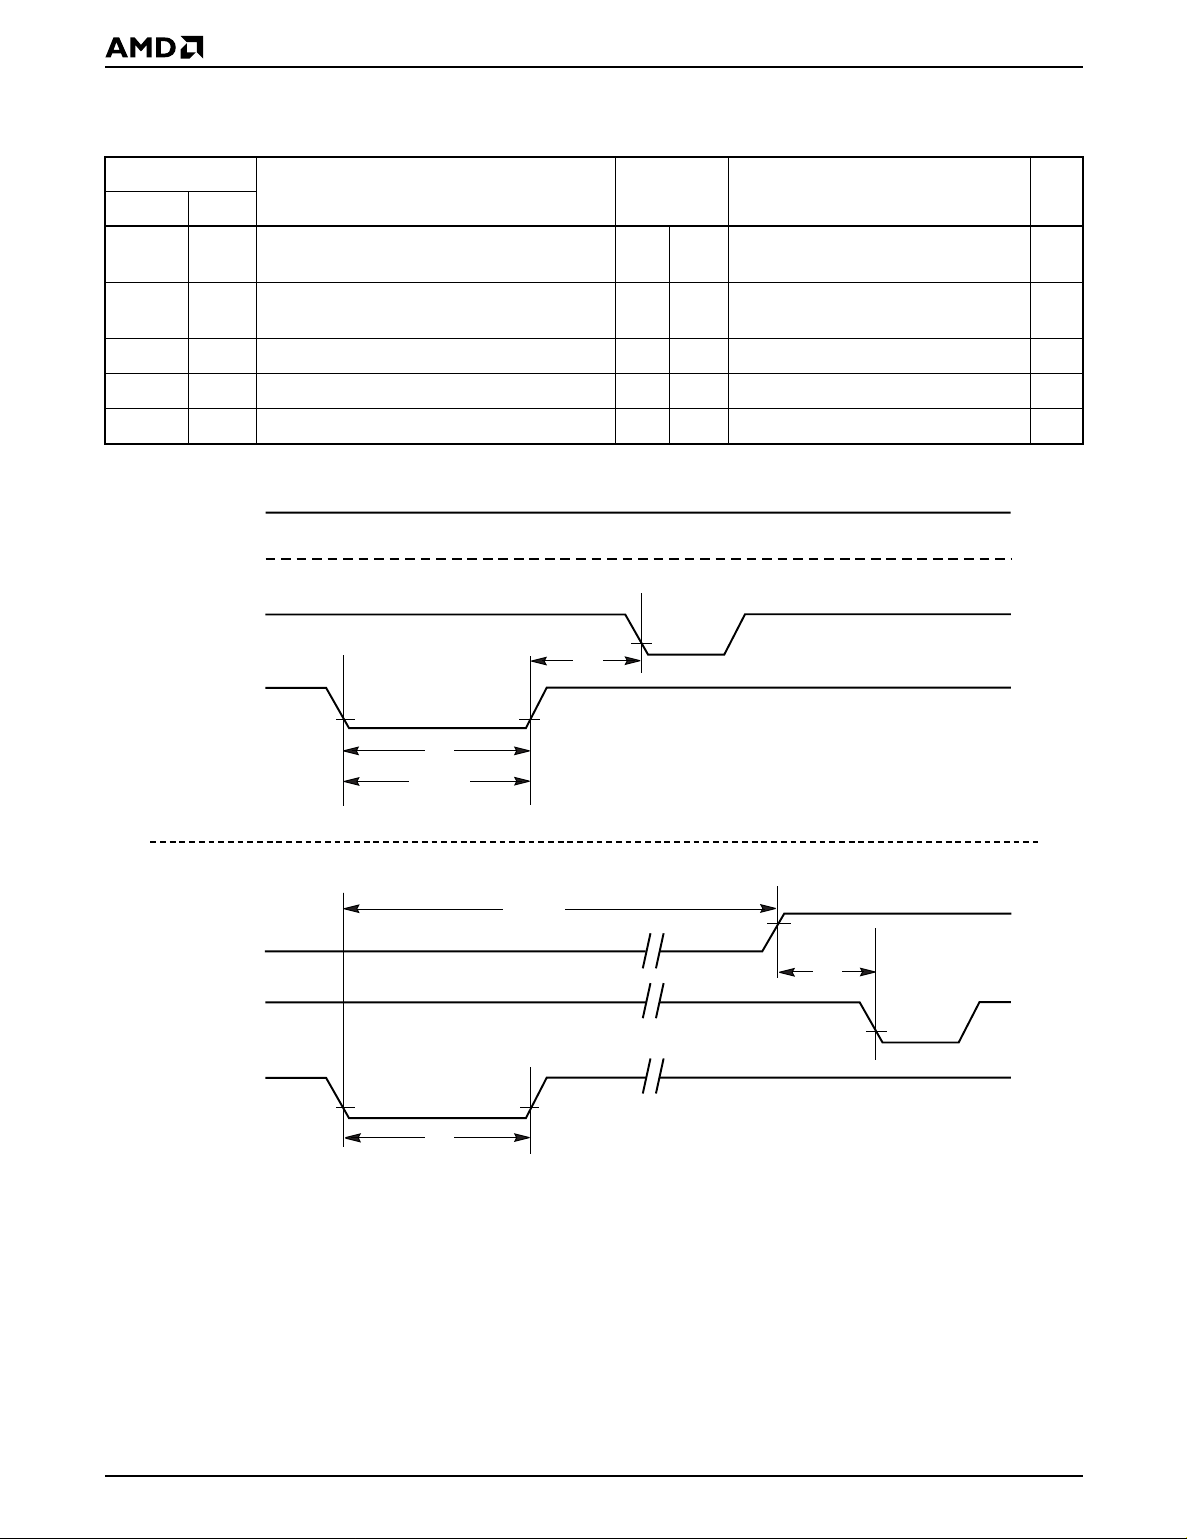
AC CHARACTERISTICS
Hardware Reset (RESET#)
Parameter
Description All Speed OptionsJEDEC Std Test Setup Unit
READY
READY
t
RP
t
RH
t
RB
RESET# Pin Low (During Embedded
Algorithms) to Read or Write (See Note)
RESET# Pin Low (NOT During Embedded
Algorithms) to Read or Write (See Note)
RESET# Pulse Width Min 500 ns
RESET# High Time Before Read (See Note) Min 50 ns
RY/BY# Recovery Time Min 0 ns
t
t
Note: Not 100% tested.
RY/BY#
CE#, OE#
RESET#
Max 20 µs
Max 500 ns
t
RH
t
RP
t
Ready
Reset Timings NOT during Embedded Algorithms
RY/BY#
CE#, OE#
RESET#
Reset Timings during Embedded Algorithms
t
Ready
t
RP
Figure 10. RESET# Timings
t
RB
21526B-13
26 Am29F200B
Page 27
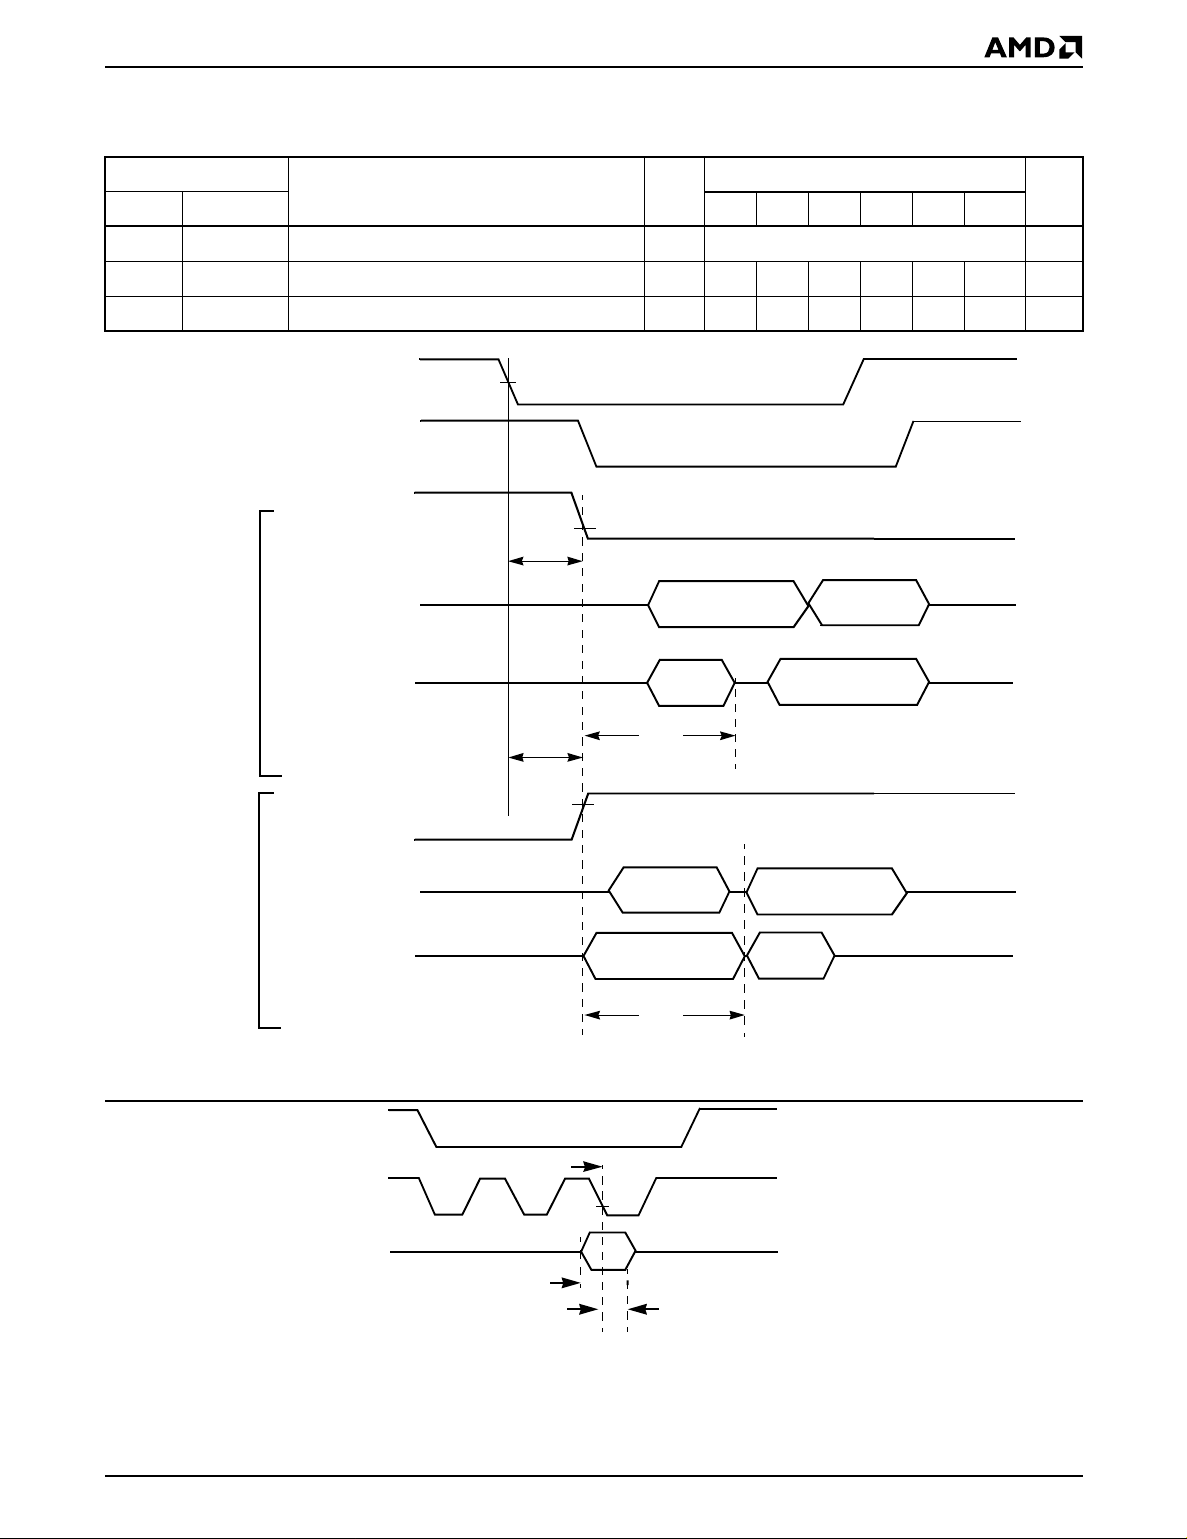
AC CHARACTERISTICS
Word/Byte Configuration (BYTE#)
Parameter Speed Options
JEDEC Std Description -45 -50 -55 -70 -90 -120 Unit
t
ELFL/tELFH
t
FLQZ
t
FHQV
CE# to BYTE# Switching Low or High Max 5 ns
BYTE# Switching Low to Output HIGH Z Max 20 20 20 20 20 30 ns
BYTE# Switching High to Output Active Max 45 50 55 70 90 120 ns
CE#
OE#
BYTE#
BYTE#
Switching
DQ0–DQ14
ELFL
Data Output
(DQ0–DQ14)
Data Output
(DQ0–DQ7)
t
from word
to byte
mode
DQ15/A-1
t
ELFH
t
FLQZ
DQ15
Output
Address
Input
BYTE#
BYTE#
Switching
from byte
DQ0–DQ14
to word
mode
DQ15/A-1
Figure 11. BYTE# Timings for Read Operations
CE#
WE#
BYTE#
Note:
Refer to the Erase/Program Operations table for t
Figure 12. BYTE# Timings for Write Operations
Data Output
(DQ0–DQ7)
The falling edge of the last WE# signal
t
SET
(tAS)
and tAH specifications.
AS
Address
Input
t
FHQV
t
HOLD
Data Output
(DQ0–DQ14)
DQ15
Output
21526B-14
(tAH)
21526B-15
Am29F200B 27
Page 28
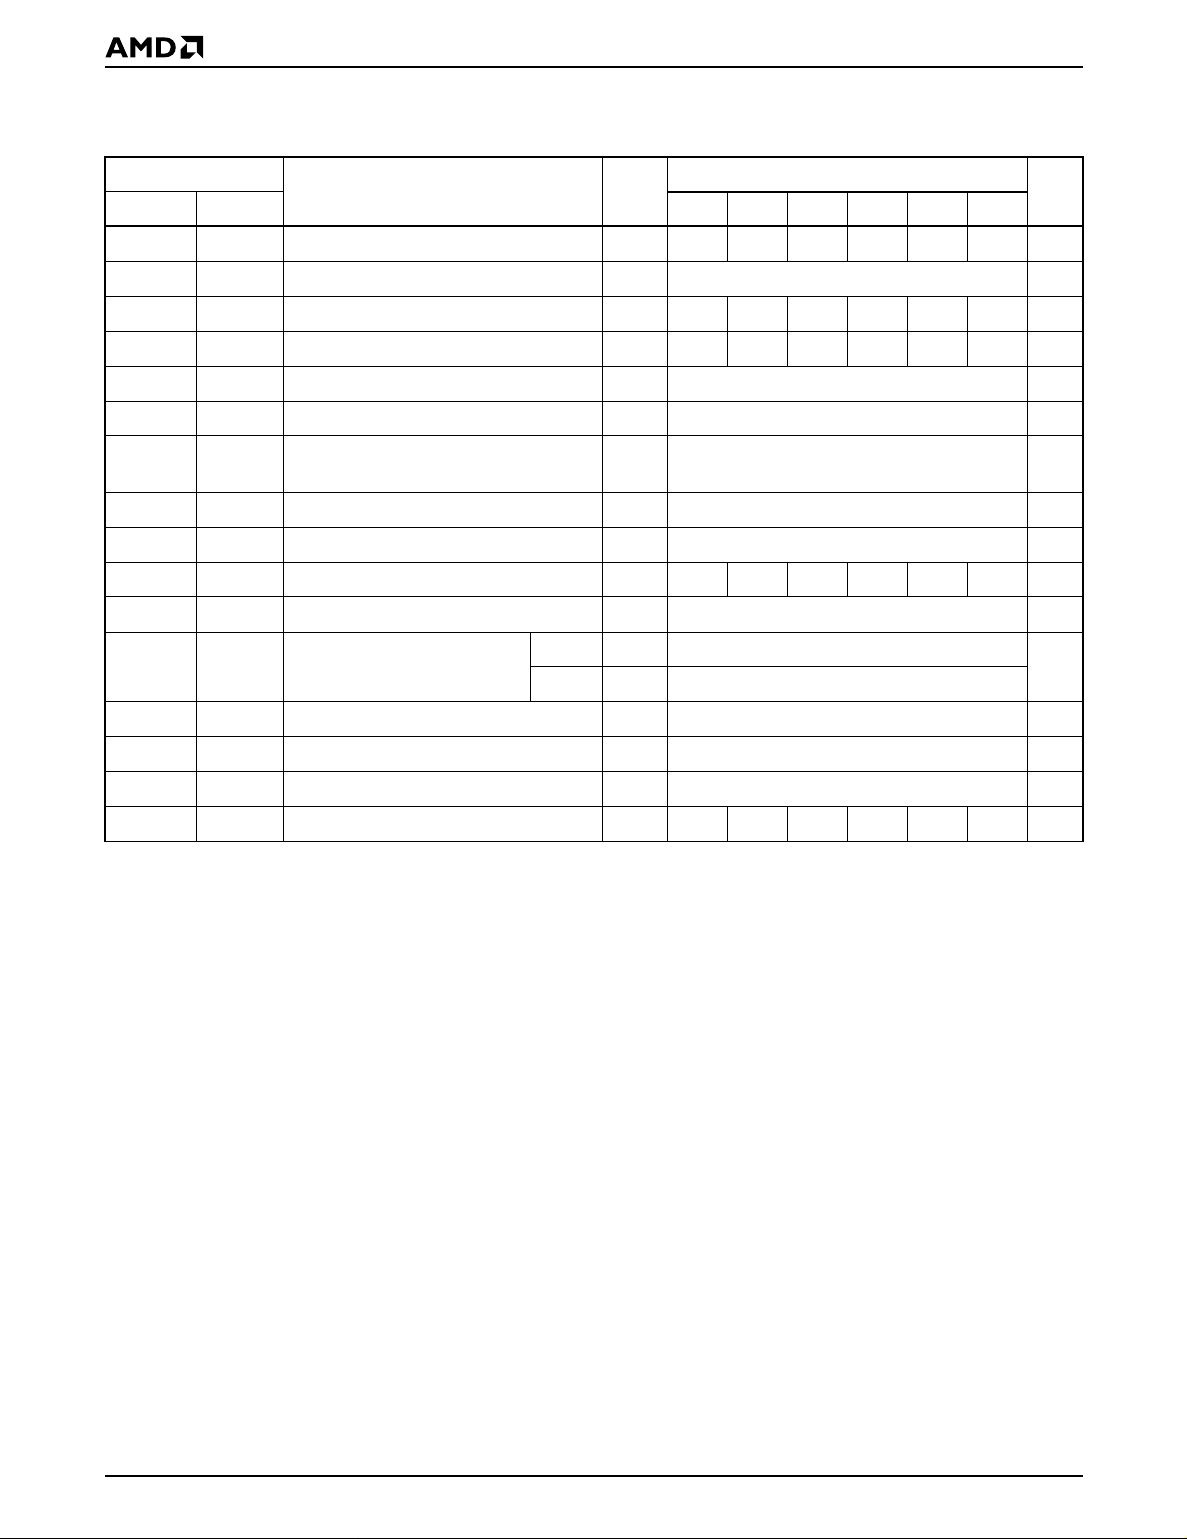
AC CHARACTERISTICS
Erase/Program Operations
Parameter Speed Options
JEDEC Std Description -45 -50 -55 -70 -90 -120 Unit
t
AVAV
t
AVWL
t
WLAX
t
DVWH
t
WHDX
t
GHWL
t
ELWL
t
WHEH
t
WLWH
t
WHWL
t
WHWH1tWHWH1
t
WHWH2tWHWH2
t
WC
t
AS
t
AH
t
DS
t
DH
t
OES
t
GHWL
t
CS
t
CH
t
WP
t
WPH
t
VCS
t
RB
t
BUSY
Write Cycle Time (Note 1) Min 45 50 55 70 90 120 ns
Address Setup Time Min 0 ns
Address Hold Time Min 45 45 45 45 45 50 ns
Data Setup Time Min 25 25 25 30 45 50 ns
Data Hold Time Min 0 ns
Output Enable Setup Time Min 0 n s
Read Recovery Time Before Write
(OE# High to WE# Low)
Min 0 ns
CE# Setup Time Min 0 ns
CE# Hold Time Min 0 ns
Write Pulse Width Min 30 30 30 35 45 50 ns
Write Pulse Width High Min 20 ns
Programming Operation
(Note 2)
Byte Typ 7
µs
Word Typ 12
Sector Erase Operation (Note 2) Typ 1 sec
VCC Setup Time (Note 1) Min 50 µs
Recovery Time from RY/BY# Min 0 ns
Program/Erase Valid to RY/BY# Delay Min 30 30 30 30 35 50 ns
Notes:
1. Not 100% tested.
2. See the “Erase and Programming Performance” section for more information.
28 Am29F200B
Page 29
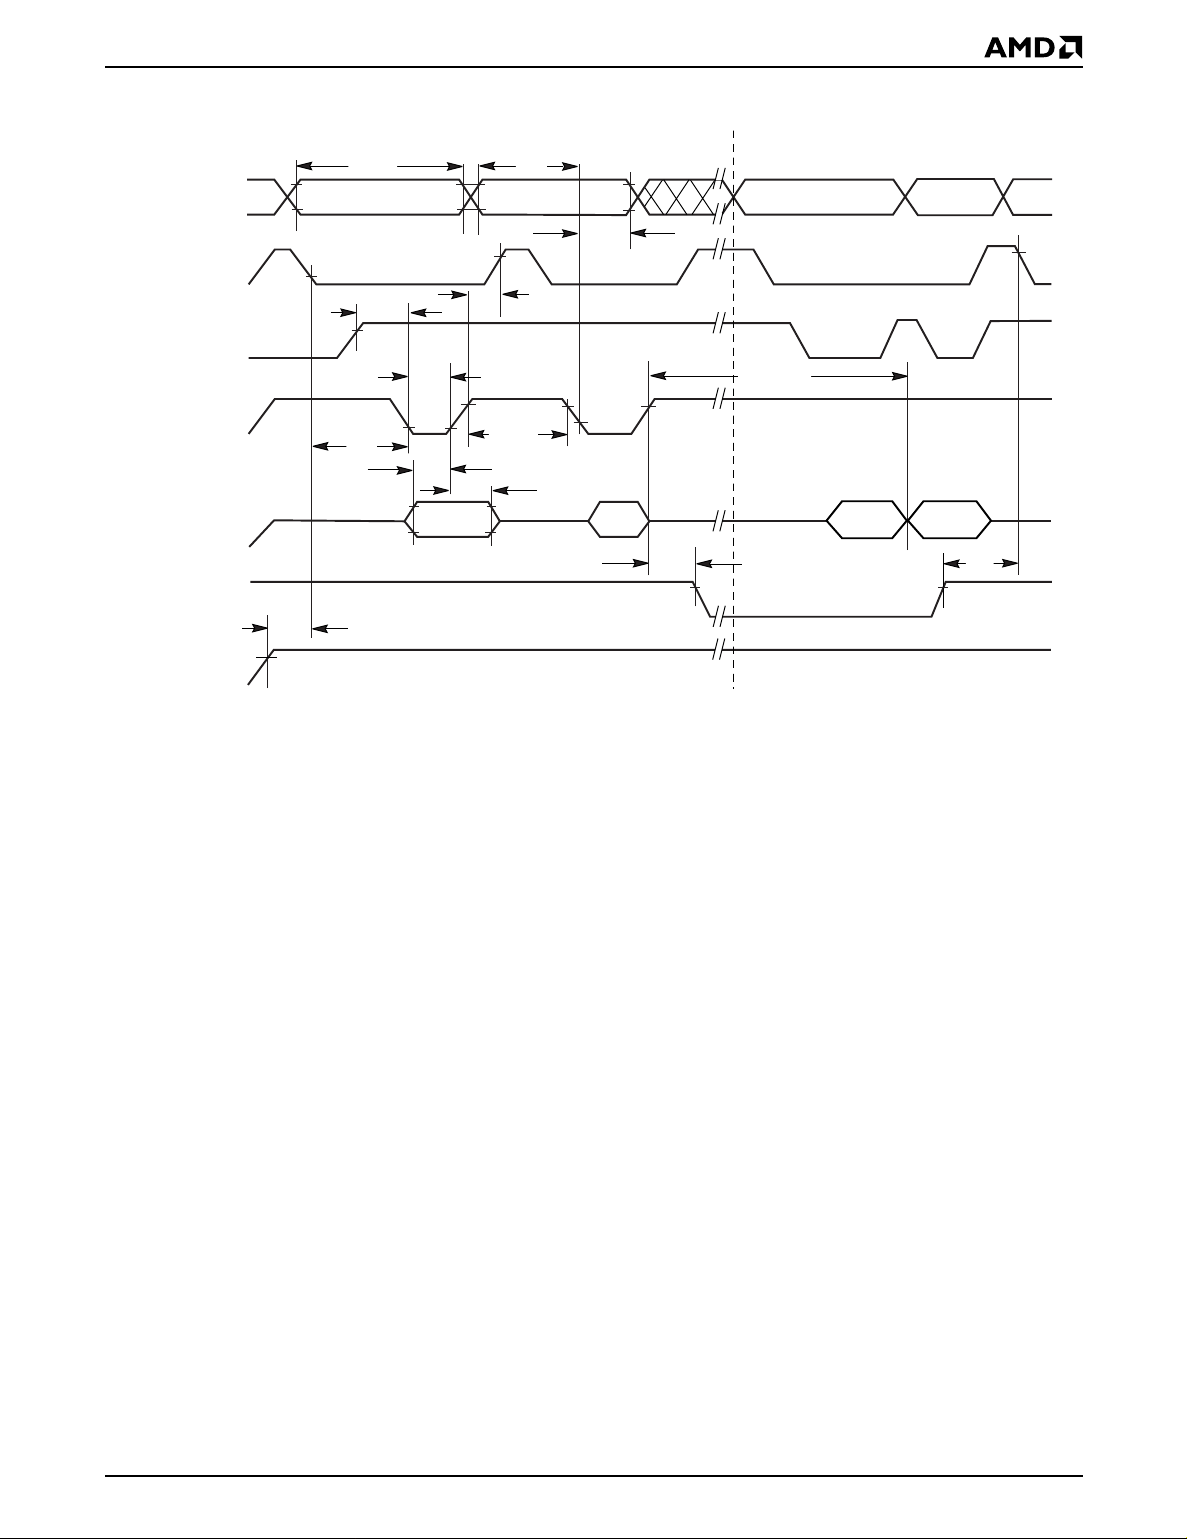
AC CHARACTERISTICS
Program Command Sequence (last two cycles)
t
WC
Addresses
555h
CE#
t
GHWL
OE#
t
WP
WE#
t
CS
t
DS
t
DH
Data
A0h
RY/BY#
t
VCS
V
CC
Notes:
1. PA = program address, PD = program data, D
2. Illustration shows device in word mode.
Figure 13. Program Operation Timing s
t
AS
PA PA
t
AH
t
CH
t
WPH
PD
t
BUSY
is the true data at the program address.
OUT
Read Status Data (last two cycles)
PA
t
WHWH1
Status
D
OUT
t
RB
21526B-16
Am29F200B 29
Page 30
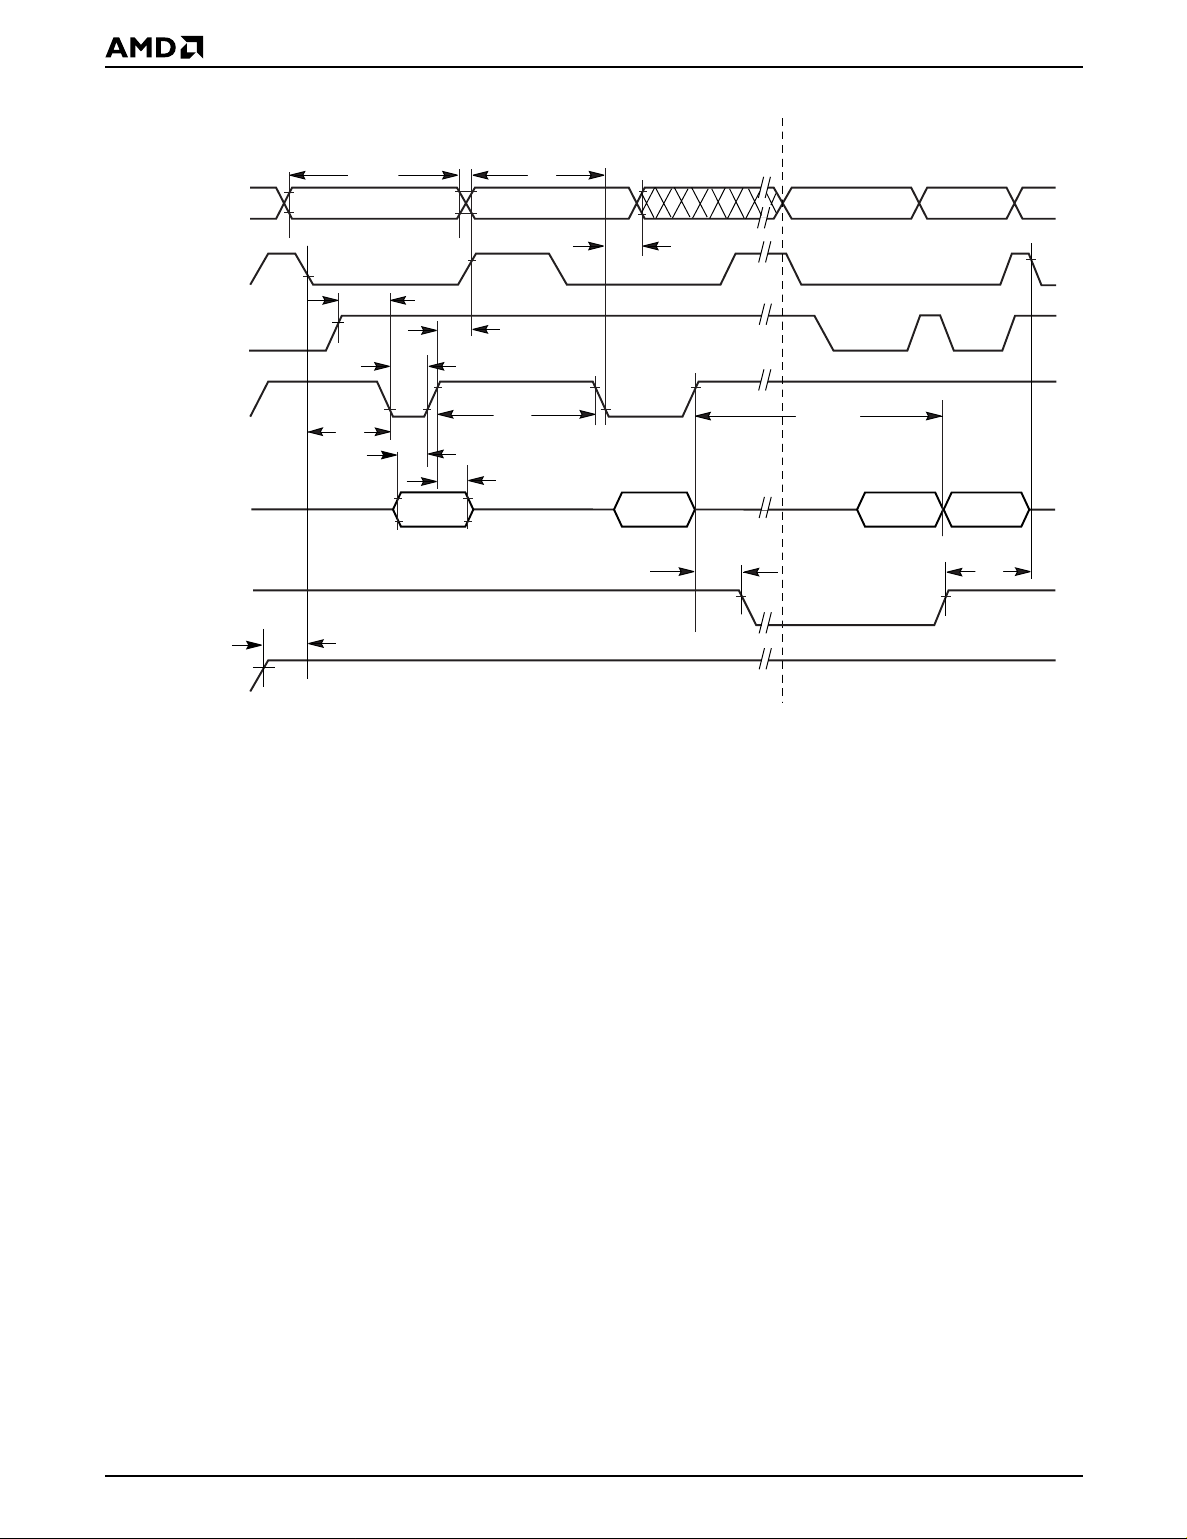
AC CHARACTERISTICS
Erase Command Sequence (last two cycles) Read Status Data
t
AS
555h for chip erase
VA
t
AH
VA
Addresses
t
WC
2AAh SA
CE#
t
GHWL
t
t
WP
t
DS
55h
t
CH
DH
t
WPH
30h
10 for Chip Erase
t
BUSY
t
WHWH2
In
Progress
Complete
t
RB
OE#
WE#
Data
t
CS
RY/BY#
t
VCS
V
CC
Notes:
1. SA = sector address (for Sector Erase), VA = Valid Address for reading status data (”see “Write Operation Status”).
2. Illustration shows device in word mode.
Figure 14. Chip/Sector Erase Operation Timings
21526B-17
30 Am29F200B
Page 31
AC CHARACTERISTICS
Addresses
CE#
t
CH
OE#
t
WE#
DQ7
OEH
t
ACC
t
CE
t
VA
t
RC
OE
t
t
OH
Complement
DF
VA VA
Complement
True
Valid Data
High Z
DQ0–DQ6
t
BUSY
Status Data
Status Data
True
Valid Data
High Z
RY/BY#
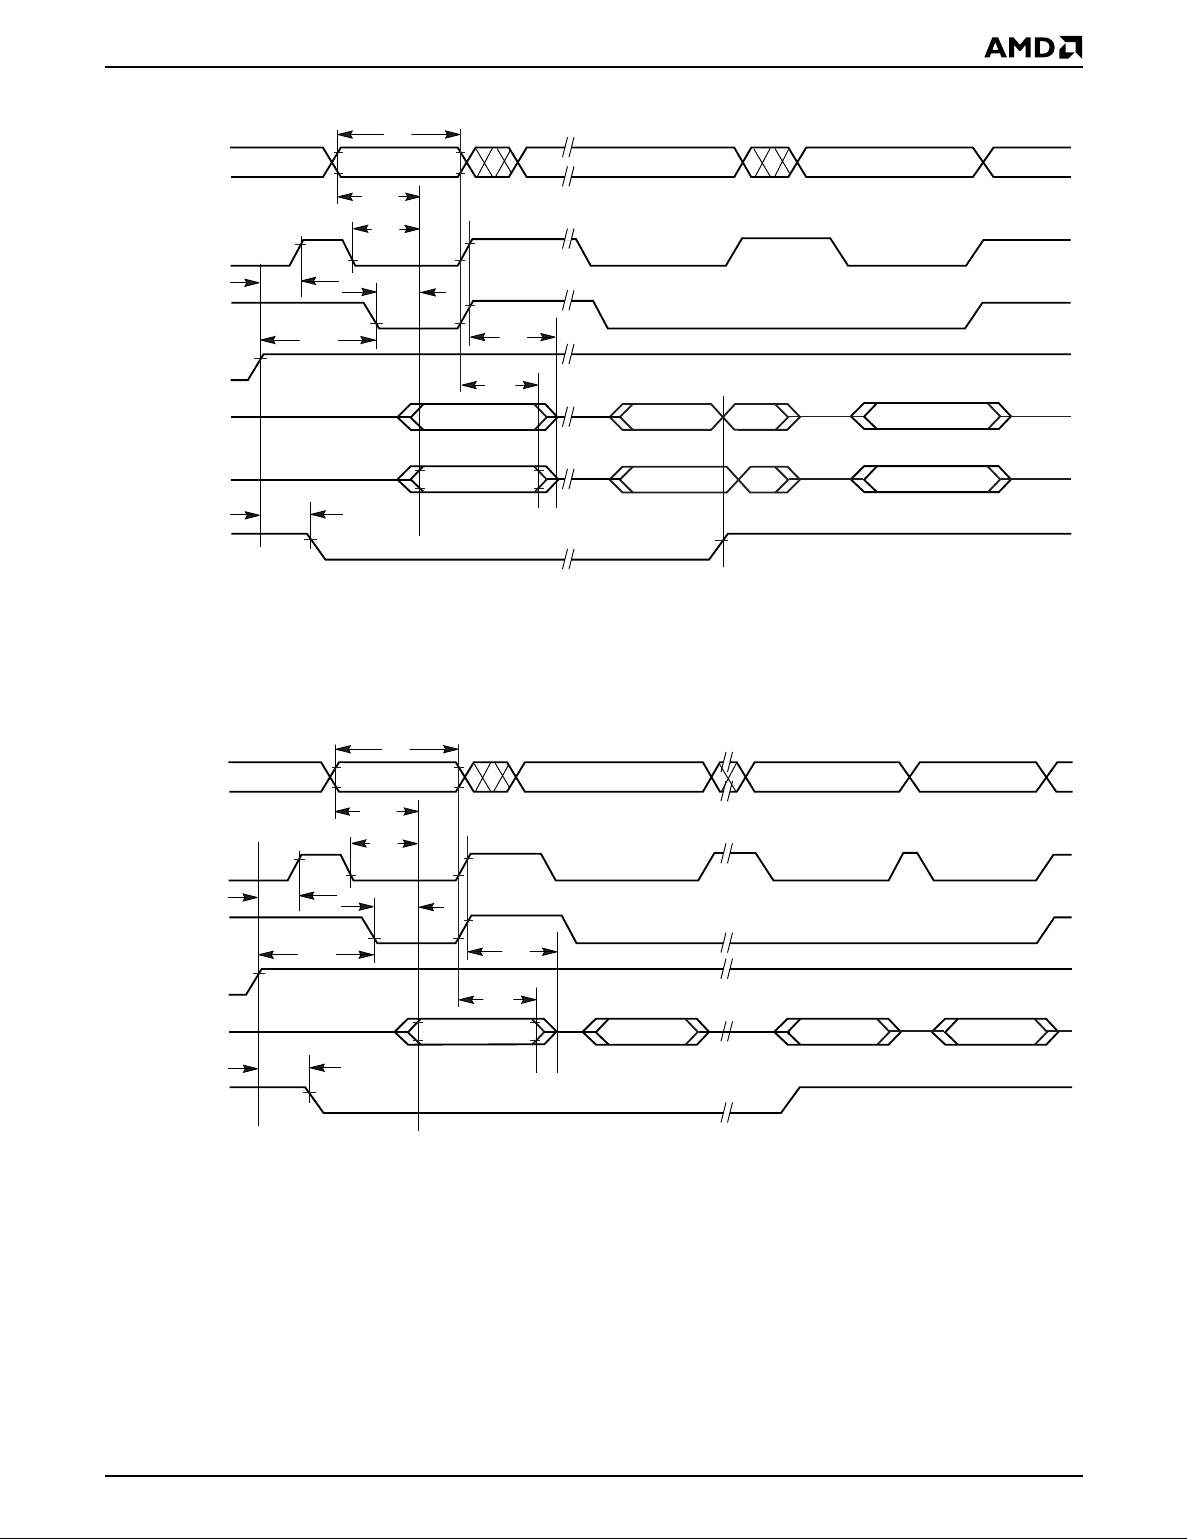
Note: VA = Valid address. Illustration shows first status cycle after command sequence, last status read cycle, and array data
read cycle.
21526B-18
Figure 15. Data# Polling Timings (During Embedded Algorithms)
t
RC
Addresses
CE#
OE#
WE#
DQ6/DQ2
RY/BY#
t
CH
t
BUSY
t
OEH
High Z
t
ACC
t
CE
VA
t
OE
t
DF
t
OH
(first read) (second read) (stops toggling)
VA VA
Valid Status
VA
Valid DataValid StatusValid Status
Note: VA = Valid address; not required for DQ6. Illustration shows first two status cycle after command sequence, last status
read cycle, and array data read cycle
21526B-19
Figure 16. Toggle Bit Timings (During Embedded Algorithms)
Am29F200B 31
Page 32
AC CHARACTERISTICS
-
Enter
Embedded
Erasing
WE#
DQ6
DQ2
Erase
Erase
Suspend
Erase Suspend
Suspend Program
Read
Enter Erase
Erase
Suspend
Program
Erase Suspend
Read
Erase
Resume
Erase
Erase
Complete
Note: The system may use OE# or CE# to toggle DQ2 and DQ6. DQ2 toggles only when read at an address within the erase-sus
pended sector.
21526B-20
Figure 17. DQ2 vs. DQ6
Temporary Sector Unprotect
Parameter
All Speed OptionsJEDEC Std Description Unit
t
t
VID Rise and Fall Time (See Note) Min 500 ns
VIDR
RESET# Setup Time for Temporary Sector
RSP
Unprotect
Min 4 µs
Note: Not 100% tested.
RESET#
CE#
WE#
RY/BY#
12 V
0 or 5 V
t
VIDR
Program or Erase Command Sequence
t
RSP
Figure 18. Tem pora ry Sector Unprotect Timi ng Diagram
t
VIDR
0 or 5 V
21526B-21
32 Am29F200B
Page 33
AC CHARACTERISTICS
Alternate CE# Controlled Erase/Program Operations
Parameter Speed Options
JEDEC S td Descript ion -45 -50 -55 -70 -90 -120 Unit
t
t
AVAV
t
AVEL
t
ELAX
t
DVEH
t
EHDX
t
GHEL
t
WLEL
t
EHWH
t
ELEH
t
EHEL
t
WHWH1tWHWH1
t
Write Cycle Time (Note 1) Min 45 50 55 70 90 120 ns
WC
t
Address Setup Time Min 0 ns
AS
t
Address Hold Time Min 45 45 45 45 45 50 ns
AH
t
Data Setup Time M in 2 5 25 25 30 45 50 ns
DS
t
Data Hold Time Min 0 ns
DH
Output Enable Setup Time Min 0 ns
t
OES
Read Recovery Time Before Write
GHEL
(OE# High to WE# Low)
t
WE# Setup Time Min 0 ns
WS
t
WE# Hold Time Min 0 ns
WH
t
CE# Pulse Width Min 30 30 30 35 45 50 ns
CP
t
CE# Pulse Width High Min 20 ns
CPH
Programming Operation
(Note 2)
Byte Typ 7
Word Typ 12
Min 0 ns
µs
t
WHWH2tWHWH2
Sector Erase Operation (Note 2) Typ 1 sec
Notes:
1. Not 100% tested.
2. See the “Erase and Programming Performance” section for more information.
Am29F200B 33
Page 34
AC CHARACTERISTICS
Addresses
WE#
OE#
CE#
Data
RESET#
555 for program
2AA for erase
t
WC
t
WH
t
WS
t
RH
PA for program
SA for sector erase
555 for chip erase
t
AS
t
GHEL
t
CP
t
CPH
t
DS
t
DH
A0 for program
55 for erase
t
AH
t
PD for program
30 for sector erase
10 for chip erase
BUSY
Data# Polling
t
WHWH1 or 2
PA
DQ7# D
OUT
RY/BY#
Notes:
1. PA = Program Address, PD = Program Data, SA = Sector Address, DQ7# = Complement of Data Input, D
2. Figure indicates the last two bus cycles of the command sequence, with the device in word mode.
Figure 19. Alternate CE# Controlled Write Operation Timings
= Array Data.
OUT
21526B-22
34 Am29F200B
Page 35
ERASE AND PROGRAMMING PERFORMANCE
Limits
Parameter
Sector Erase Time 1 8 sec
Chip Erase Time 5 sec
Byte Programming Time 7 300 µs
Word Programming Time 12 500 µs
Chip Programming Time (Note 3) 1.8 5.4 sec
Excludes 00h programming prior to
erasure (Note 4)
Excludes system-level overhead
(Note 5)
CommentsTyp (Note 1) Max (Note 2) Unit
Notes:
1. Typical program and erase times assume the following conditions: 25×C, 5.0 V V
, 1,000,000 cycles. Additionally,
CC
programming typicals assume checkerboard pattern.
2. Under worst case conditions of 90°C, V
= 4.5 V (VCC = 4.75 V for ±5% devices), 1,000,000 cycles.
CC
3. The typical chip programming time is considerably less than the maximum chip programming time listed, since most bytes
program faster than the maximum byte program time listed.
4. In the pre-programming step of the Embedded Erase algorithm, all bytes are programmed to 00h before erasure.
5. System-level overhead is the time required to execute the four-bus-cycle command sequence for programming. See Table 1
for further information on command definitions.
6. The device has a guaranteed minimum erase and program cycle endurance of 1,000,000 cycles.
LATCHUP CHARACTERISTICS
Parameter Description Min Max
Input Voltage with respect to V
Current –100 mA +100 mA
V
CC
on all I/O pins –1.0 V VCC + 1.0 V
SS
Note: Includes all pins except VCC. Test conditions: VCC = 5.0 V, one pin at a time.
TSOP AND SO PIN CAPACITANCE
Parameter
Symbol Parameter Description Test Setup Typ Max Unit
Input Capacitance VIN = 0 6 7.5 pF
Output Capacitance V
Control Pin Capacitance VIN = 0 8 10 pF
= 0 8.5 12 pF
OUT
C
C
C
OUT
IN2
IN
Notes:
1. Sampled, not 100% tested.
2. Test conditions TA = 25°C, f = 1.0 MHz.
DATA RETENTION
Parameter Test Conditions Min Unit
Minimum Pattern Data Retention Time
150°C 10 Years
125°C 20 Years
Am29F200B 35
Page 36
PHYSICAL DIMENSIONS
SO 044—44-Pin Small Outline Package (measured in millimeters)
2.17
2.45
44
23
13.10
13.50
1
1.27 NOM.
TOP VIEW
28.00
28.40
0.35
0.50
SIDE VIEW
22
0.10
0.35
2.80
MAX.
15.70
16.30
SEATING
PLANE
0°
8°
0.10
0.21
0.60
1.00
END VIEW
16-038-SO44-2
SO 044
DF83
8-8-96 lv
36 Am29F200B
Page 37
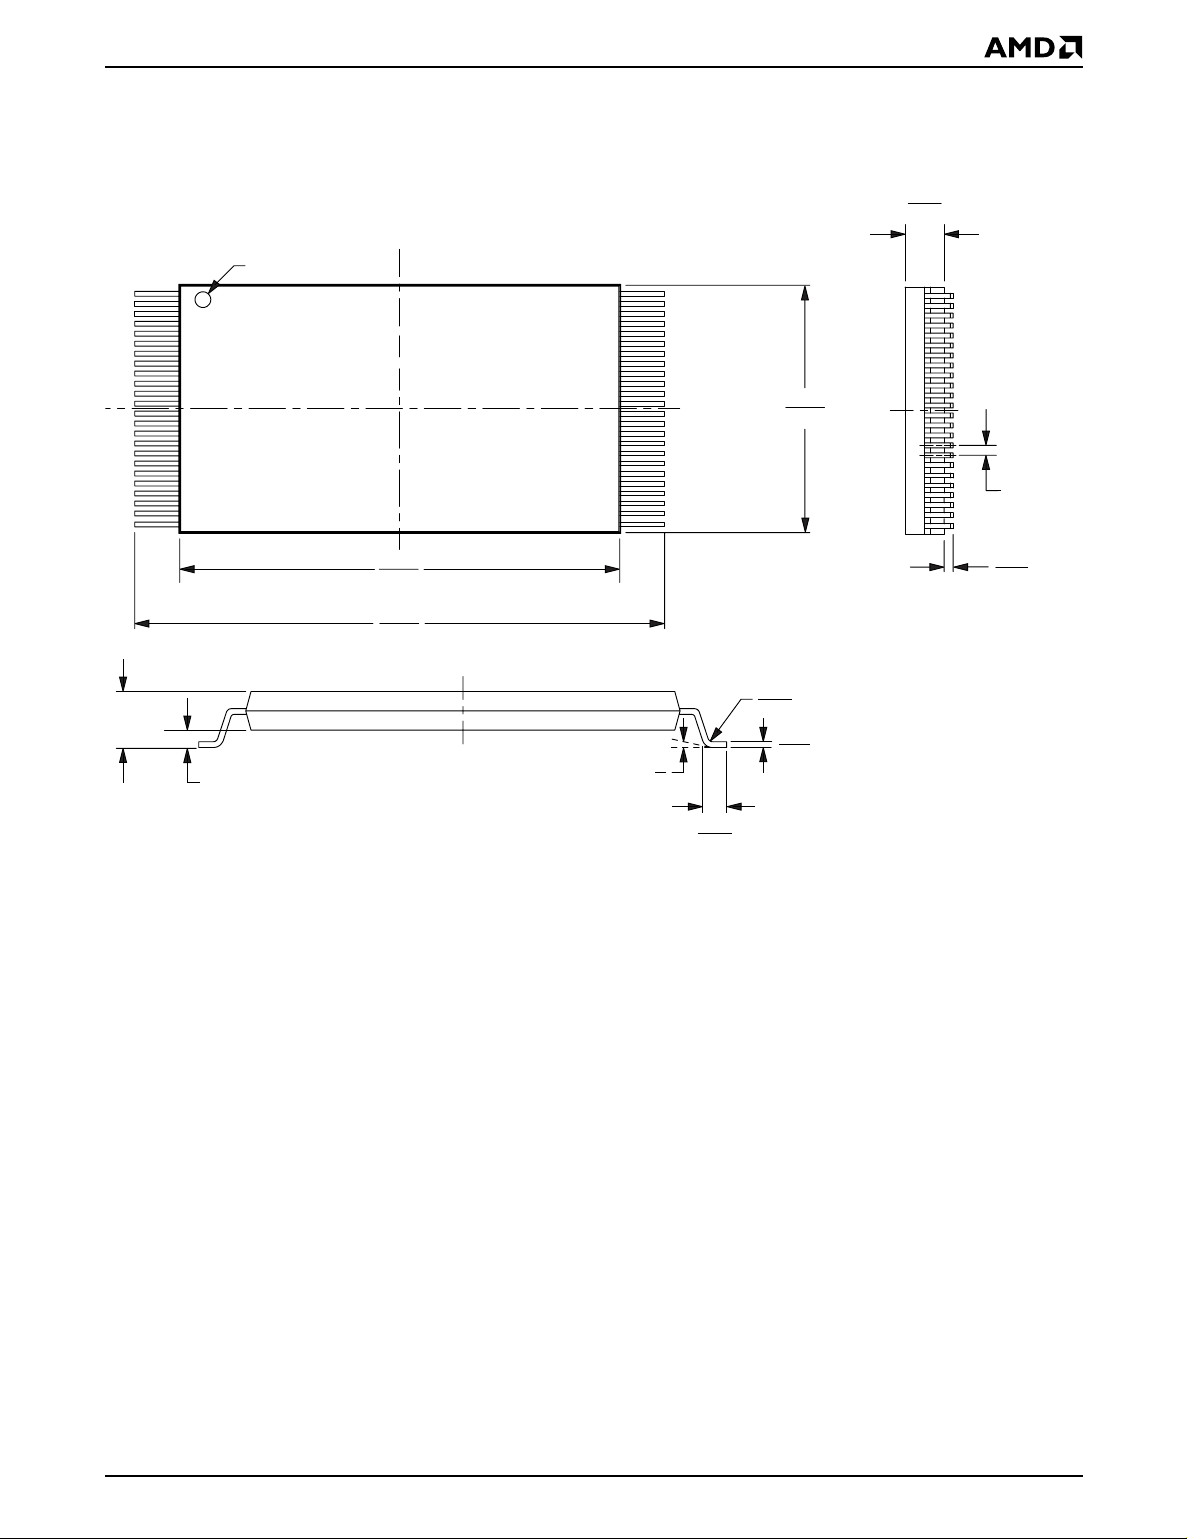
PHYSICAL DIMENSIONS
TS 048—48-Pin Standard Thin Small Outline Package (measured in millimeters)
0.95
1.05
Pin 1 I.D.
1
24
18.30
18.50
19.80
20.20
48
11.90
12.10
25
0.50 BSC
0.05
0.15
1.20
MAX
0.25MM (0.0098") BSC
0.08
0.20
0.10
0°
0.21
16-038-TS48-2
TS 048
DT95
8-8-96 lv
5°
0.50
0.70
Am29F200B 37
Page 38
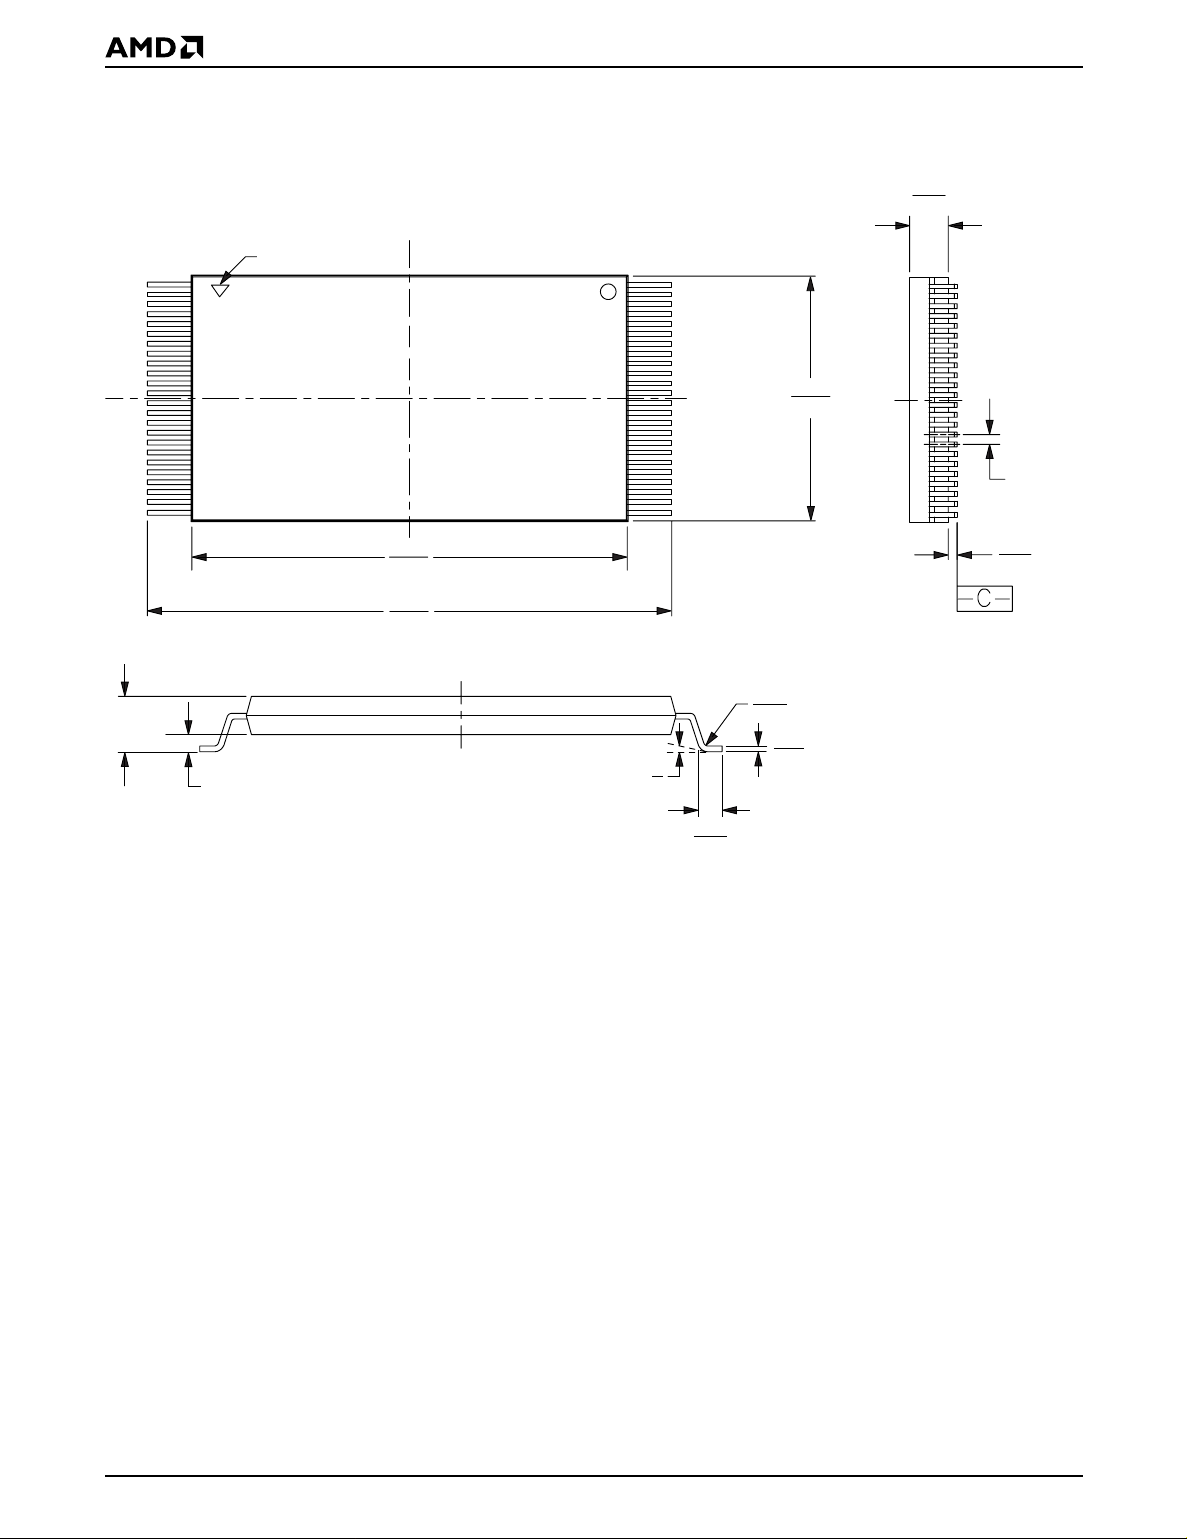
PHYSICAL DIMENSIONS
TSR048—48-Pin Reverse Thin Small Outline Package (measured in millimeters)
0.95
1.05
Pin 1 I.D.
1
24
18.30
18.50
19.80
20.20
1.20
MAX
0.25MM (0.0098") BSC
48
11.90
12.10
25
SEATING PLANE
16-038-TS48
0.08
0.20
TSR048
DT95
8-8-96 lv
0.10
0°
0.21
5°
0.50 BSC
0.05
0.15
0.50
0.70
38 Am29F200B
Page 39
REVISION SUMMARY
Revision A
Global: Made formatting and layout consistent with other
data sheets. Used updated common tables and diagrams
Revision B
Distinctive Characteristics
Added bullet for 20-year data retention at 125°C
Ordering Information
Optional Processing
DC Characteristics—TTL/NMOS Compatible
I
, I
CC2
, I
CC3
CC1
cations are tested with V
DC Characteristics—CMOS Compatible
I
, I
CC2
, I
CC3
CC1
cations are tested with V
: Deleted “B = Burn-in”.
: Added Note 2 “Maximum ICC specifi-
CC
= V
CCmax
”.
: Added Note 2 “Maximum ICC specifi-
CC
= V
CCmax
”.
AC Characteristics
Figure 15. Data# Polling Timings (During Embedded
Algorithms)
: Added text to note.
Figure 16. Toggle Bit Timings (During Embedded Algorithms)
: Added text to note .
Revision B+1 (April 12, 1999)
Product Selector Guide
The 55 ns option now has a VCC operating range of
±10%.
Revision B+2 (July 2, 1999)
Global
Added referenc es to availability of device in K nown
Good Die (KGD) form.
Trademarks
Copyright © 1999 Advanced Micro Devices, Inc. All rights reserved.
AMD, the AMD logo, and combinations thereof are registered trademarks of Advanced Micro Devices, Inc.
ExpressFlash is a trademark of Advanced Micro Devices, Inc.
Product names used in this publication are for identification purposes only and may be trademarks of their respective companies.
Am29F200B 39
 Loading...