

Page 1
Conner Filepro Performance Series
CFP1060E/CFP1060S/CFP1060W
Intelligent Disk Drive
Product Manual
Revision A
May 1994
3081 Zanker Road
San Jose, CA 95134-2128
(408) 456-4500
Page 2
Page 3
FCC Notice
This equipment generates and uses radio frequency energy and, if not installed
and used properly; that is, in strict accordance with the manufacturer's
instructions, may cause interference to radio and television reception. It has
been type tested and found to comply with the limits for a Class B computing
device in accordance with the specifications in Part 15 of FCC Rules, which are
designed to provide reasonable protection against such interference in a
residential installation. However, there is no guarantee that interference will
not occur in a particular installation. If this equipment does cause interference
to radio or television reception, which can be determined by turning the
equipment on and off, you are encouraged to try to correct the interference by
one or more of the following measures:
• Reorient the receiving antenna.
• Relocate the computer with respect to the receiver.
• Move the computer into a different outlet so that the computer and receiver
are on different branch circuits.
If necessary, you should consult the dealer or an experienced radio/television
technician for additional suggestions. You may find the following booklet
prepared by the Federal Communications Commission helpful:
How to Identify and Resolve Radio-TV Interference Problems
This booklet (Stock No. 004-000-00345-4) is available from the U.S. Government
Printing Office, Washington, DC 20402.
Warning: Changes or modifications made to this equipment which have not
been expressly approved by Conner Peripherals, Inc. may cause radio and
television interference problems that could void the user's authority to operate
the equipment.
Further, this equipment complies with the limits for a Class B digital apparatus
in accordance with Canadian Radio Interference Regulations.
Cet appareil numérique de la classe B est conforme au Règlement sur le
brouillage radioélectrique, C.R.C., ch. 1374.
Conner and the Conner logo are registered trademarks of Conner Peripherals,
Inc. All other trademarks mentioned in this manual are property of their
respective owners.
Copyright 1994, Conner Peripherals, Inc.
All rights reserved.
Document No. 501-064 5/94
Page 4
Important Information About This Manual
All information contained in or disclosed by this document is considered
proprietary by Conner Peripherals, Inc. By accepting this material, the recipient
agrees that this material and the information contained therein are held in
confidence and in trust and will not be used, reproduced in whole or in part, nor
its contents revealed to others, except to meet the purpose for which it was
delivered. It is understood that no right is conveyed to reproduce or translate
any item herein disclosed without express written permission from Conner
Peripherals, Inc.
Conner Peripherals, Inc. provides this manual "as is," without warranty of any
kind, either expressed or implied, including, but not limited to, the implied
warranties of merchantability and fitness for a particular purpose. Conner
Peripherals, Inc. reserves the right to change, without notification, the
specifications contained in this manual.
Conner Peripherals, Inc. assumes no responsibility for the accuracy,
completeness, sufficiency, or usefulness of this manual, nor for any problem that
might arise from the use of the information in this manual.
Page 5
Table of Contents
1. Overview of the Drives 1
What are the Drives? 1
Features of the Drive 3
What the Drive is Composed Of 4
2. Specifications 9
Specifications in this Chapter 9
Differences Between the Models 1
Mechanical Design Features 4
Drive Assembly Housing 5
Head Positioning Mechanism 6
Read/Write Heads and Disks 6
Data and Power Connections 6
Electrical Design Features 6
Integrated Circuit 6
Circuit Board 6
Firmware 7
Drive Capacity 10
Formatted Capacity 10
Physical Configuration 10
Physical Configuration per Zone 10
Performance Characteristics 11
Seek Times (typical)* 11
Average Latency 11
Rotation Speed (+0.1%) 11
Controller Overhead 11
Start Time(Power Up)* 11
Stop Time at Power Down 11
Interleave 11
Read/Write Characteristics 12
Recording Method 12
Recording Density (maximum) 12
Flux Density (maximum) 12
Host Interface Characteristics 12
Command Set 12
Data Transfer Rate 12
Maximum Synchronous Transfer Offset: 12
Maximum Tagged Command Queue Depth: 12
Buffer Size: 12
Reliability 13
Data Reliability 13
Component Design Life 13
Start/Stop cycles 13
Mean Time Between Failures: 13
Mean Time to Repair 13
Preventive Maintenance 13
Power Requirements (Typical) 14
Minimum/Maximum Voltage: 14
Technical Reference Manual Page i
Page 6
Filepro CFP1060E/CFP1060S/CFP1060W Table of Contents
Environmental Tolerances 15
Magnetic Field: 15
Acoustic Noise: 15
Safety Standards 16
Physical Characteristics - CFP1060E 17
Physical Characteristics - CFP1060S 18
Physical Characteristics - CFP1060W 19
3. How the Drive Operates 21
Functions of the Drive 21
Drive Operational Modes 21
Error Correction 22
Read Retry Operations 22
Downloadable Microcode 23
Buffer Management and Command Execution 24
Read Look Ahead Code 24
Write Caching 26
Tagged Command Queuing 27
Seek Re-ordering 27
Buffer Management 27
4. Installing the Drive 29
Take These Precautions 29
Installing the Drive 29
Installing a CFP1060E 30
Setting the Drive's Jumpers - 1060E 30
Setting the SCSI Bus Address - CFP1060E 30
Disabling Spin-Up at Power On - CFP1060E 31
Delaying Spin Up at Power On - CFP1060E 31
Cabling the Drive - CFP1060E 31
Attaching Power to the Drive - CFP1060E 31
Mounting the Drive - CFP1060E 32
Installing a CFP1060S 33
Setting the Drive's Jumpers - CFP1060S 33
Setting the SCSI Bus Address - CFP1060S 34
Disabling Spin-Up at Power On - CFP1060S 35
Delaying Spin Up at Power On - CFP1060S 35
Disabling the SCSI Bus Parity - CFP1060S 36
Disabling SCSI Bus Terminator Power (TERMPWR) -
CFP1060S 36
Setting the Bus Termination - CFP1060S 37
Cabling the Drive - CFP1060S 38
SCSI Bus Cable 38
Spindle Synchronization 38
Attaching Power to the Drive - CFP1060S 39
Mounting the Drive - CFP1060S 39
Installing a CFP1060W 40
Setting the Drive’s Jumpers - CFP1060W 40
Setting the SCSI Bus Address - CFP1060W 41
Disabling Spin-Up at Power On - CFP1060W 42
Delaying Spin Up at Power On - CFP1060W 42
Disabling the SCSI Bus Parity - CFP1060W 42
Page ii Filepro CFP1060E/CFP1060S/CFP1060W
Page 7
Filepro CFP1060E/CFP1060S/CFP1060W Table of Contents
Disabling SCSI Bus Terminator Power (TERMPWR) CFP1060W 43
Using the J5 Auxiliary Connector 43
- SEL0 43
- XTFAULT 44
- SEL1 44
- VUNIQ 44
- SEL2 44
- SPSYNC 44
- SEL3 45
- XTACTV 45
- GROUND 45
+5 Volts 45
- FAULT 45
Setting the Bus Termination - CFP1060W 46
Cabling the Drive - CFP1060W 47
SCSI Bus Cable 47
Mixing Wide and Narrow SCSI Devices on a SCSI Bus 48
Spindle Synchronization 48
Attaching Power to the Drive - CFP1060W 49
Mounting the Drive - CFP1060W 49
5. Interface Physical Characteristics 51
Electrical Description 51
Output Characteristics 51
Input Characteristics 52
Model-Specific SCSI Physical Characteristics 52
CFP1060E (WIDE, 80-pin Single Connector Attachment [SCA]) 53
External Terminator Power 53
Internal Termination 53
Cable Requirements 53
Connector Requirements 53
Single Connector Attachment (SCA) Signal Definitions 53
Power 53
Spindle Sync 54
LED Out 54
Motor Start Controls 54
SCSI ID Selection 54
Interface Pin Assignments 55
Interface Timing Requirements 56
Model CFP1060S (Narrow, 50-pin SCSI) 57
External Terminator Power 57
Internal Termination 57
Cable Requirements 58
Connector Requirements 59
Interface Pin Assignments 60
Interface Timing Requirements 61
Model CFP1060W (Wide, Unitized SCSI-3 P-Connector) 62
External Terminator Power 62
Internal Termination 62
J5 Auxiliary Connector Signal Characteristics 63
Cable Requirements 63
Connector Requirements 64
Interface Pin Assignments 65
Technical Reference Manual Page iii
Page 8
Filepro CFP1060E/CFP1060S/CFP1060W Table of Contents
Interface Timing Requirements 66
6. SCSI Command Implementation 67
SCSI Command Summary 67
Drive Dependent SCSI Data 68
Format Drive Page - 03H 68
Drive Geometry Page - 04H 70
Notch and Partition Parameters Page - 0CH 71
Page iv Filepro CFP1060E/CFP1060S/CFP1060W
Page 9
Overview of the Drives
Interface
80-pin Single Connector
FAST WIDE
50-pin FAST
68-pin FAST WIDE
What are the Drives?
The CFP1060 series are high performance 3.5-inch low-profile (1.0 inch high)
1.06 Gigabyte (formatted) disk drives. They all offer 9.0 millisecond average
seek time for Reading , 9.5 millisecond seek time for Writing, with an average
latency of only 5.55 ms. High capacity is achieved by utilizing a zone density
recording technique using 9 recording zones at an areal density of 205 Mbits per
square inch. These drives feature high performance while maintaining low
power consumption to reduce power supply current and system cooling
requirements in disk arrays.
They are designed to operate on the Small Computer System Interface (SCSI)
and are SCSI-2/3 command compatible. The mechanical and major electronic
components are identical between the models and differ only in the host
interface implementation:
1
Drive Model Form Factor
CFP1060E
CFP1060S
CFP1060W
For simplicity, we often refer to these drives collectively in this manual as “the
drive.”
1 inch high, 3.5 inch
1 inch high, 3.5 inch
1 inch high, 3.5 inch
Differences Between the Models
The three drive models differ only on the host interface implementation:
CFP1060E: SCSI 80-pin Wide Single Connector Attachment (SCA) interface
designed for applications such as Redundant Arrays in which the drives are
plugged directly into a backplane. The drive also implements a Wide SCSI
interface for high interface bandwidth.
CFP1060S: SCSI 50-pin standard interface designed for applications which
implement the standard SCSI-2 architecture.
Capacity
1062.3MB
1062.3MB
1062.3MB
Technical Reference Manual Page 1
CFP1060W: SCSI 68-pin Wide interface designed for applications which
require high interface bandwidth and the option of cabled interconnect. The
drive utilizes the Unitized Connector defined by the Small Form Factor
Committee (refer to SFF-8009). The Unitized Connector combines the SCSI-3 P-
Page 10
Chapter 1 Overview of the Drives
connector Wide interface, the standard 4-pin power and a 2mm pin pitch
Auxiliary connector into a single molded assembly.
Page 2 Filepro CFP1060E/CFP1060S/CFP1060W
Page 11
Overview of the Drives Chapter 1
Features of the Drive
The drive provide the following features:
• Automatic Spindle Synchronization
• 512 KB segmentable cache buffer with adaptive cache management
• LRU Cache replacement
• 88 bit Reed-Solomon EDAC with on the fly error correction
• High performance rotary voice coil actuator with embedded servo system
• No thermal recalibration required to maintain performance levels
• High Shock resistance
• Automatic actuator latch against the inner stop upon power down with
dedicated landing zone
• Active Termination with removable Resistor Packs
• Active Negation output drivers for greater interface reliability
• SCSI-2/3 Compatibility
• Dual Microprocessor-controlled diagnostic routines that automatically
execute at start-up
• Sealed HDA
• Automatic error correction
• Down-loadable Code through SCSI Interface
• 1,7 run length limited code
• Programmable Block Size (512-520 in 1 byte increments, 1024-1040 in 2
byte increments)
• Tagged Command Queuing with Seek Re-ordering and Write/Read
Coalescing
Technical Reference Manual Page 3
Page 12
Chapter 1 Overview of the Drives
What the Drive is Composed Of
The drive is composed of mechanical, electrical, and firmware elements.
Mechanical Design Features
The drive’s hardware includes the components described in the following
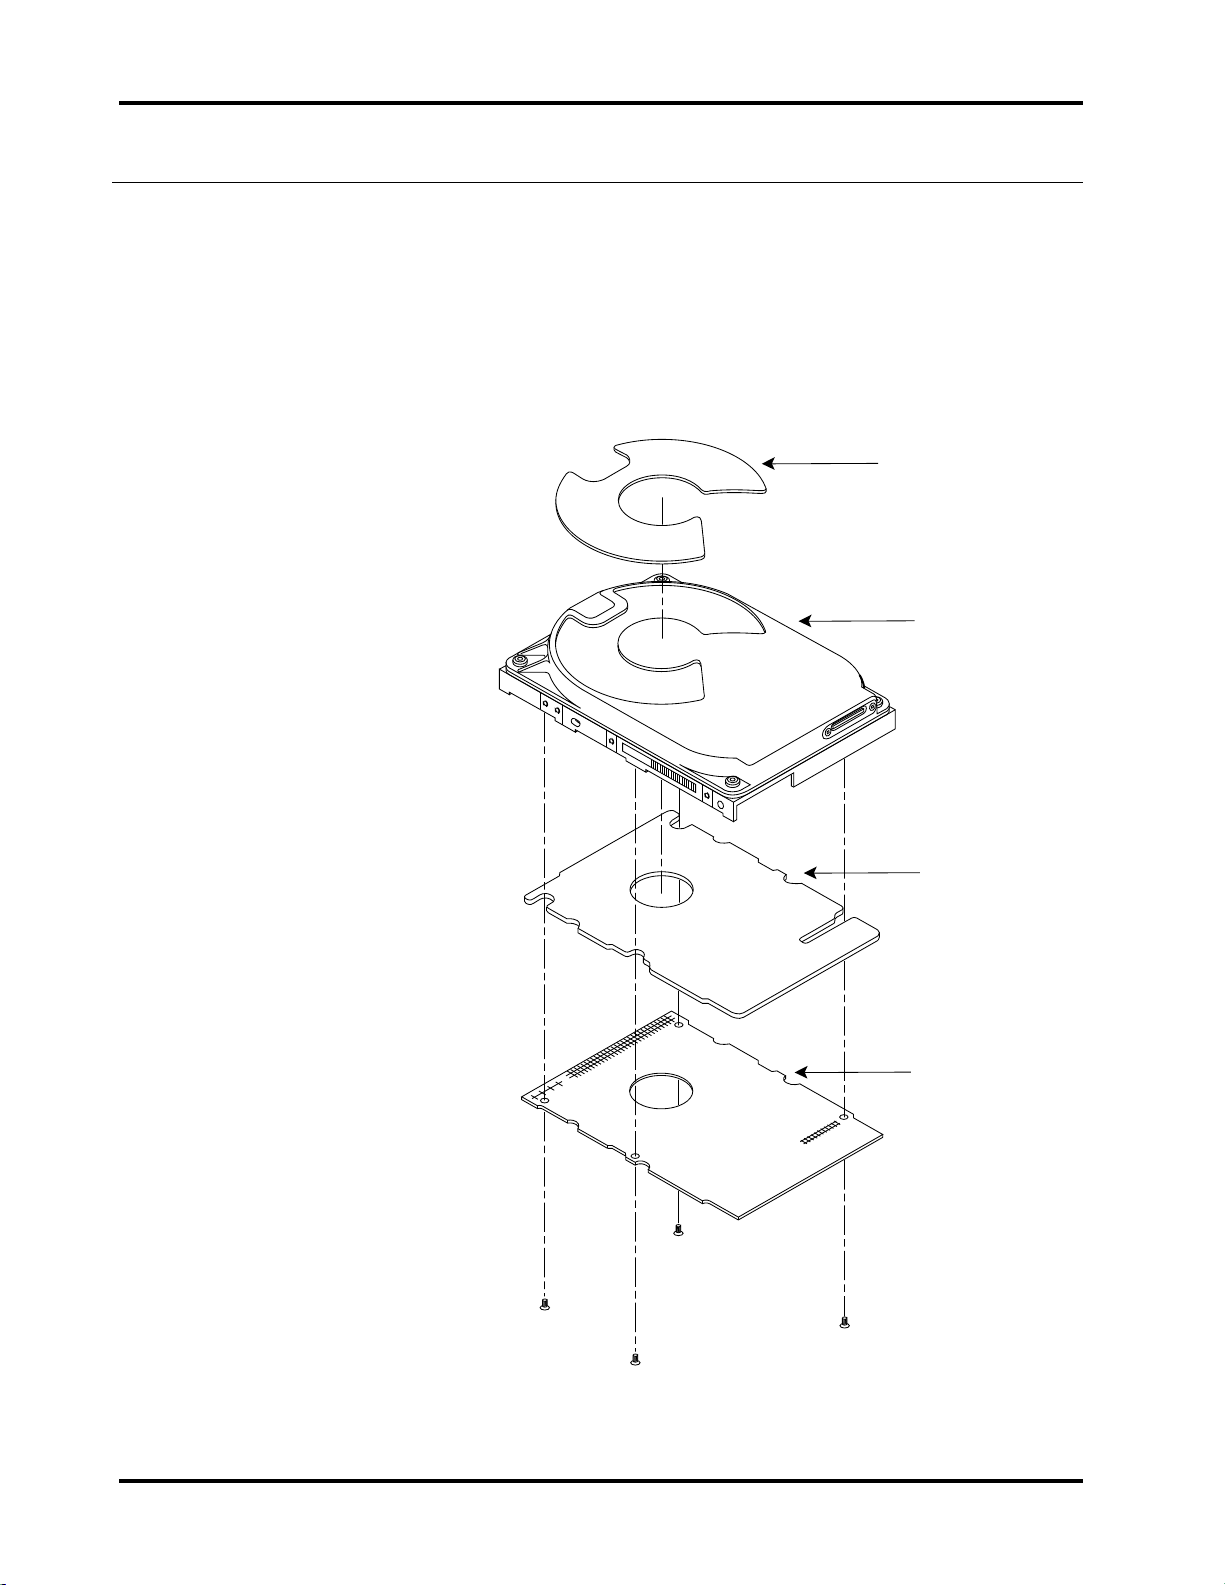
sections. Figure 1-1 shows the drive top level assembly.
Figure 1-1
Drive Top Level Assembly
Damper
Head-Disk
Assembly
1060-1-1
Printed Circuit
Board Assembly
Shield
Printed
Circuit
Board
Assembly
Page 4 Filepro CFP1060E/CFP1060S/CFP1060W
Page 13
Overview of the Drives Chapter 1
Drive Assembly Housing
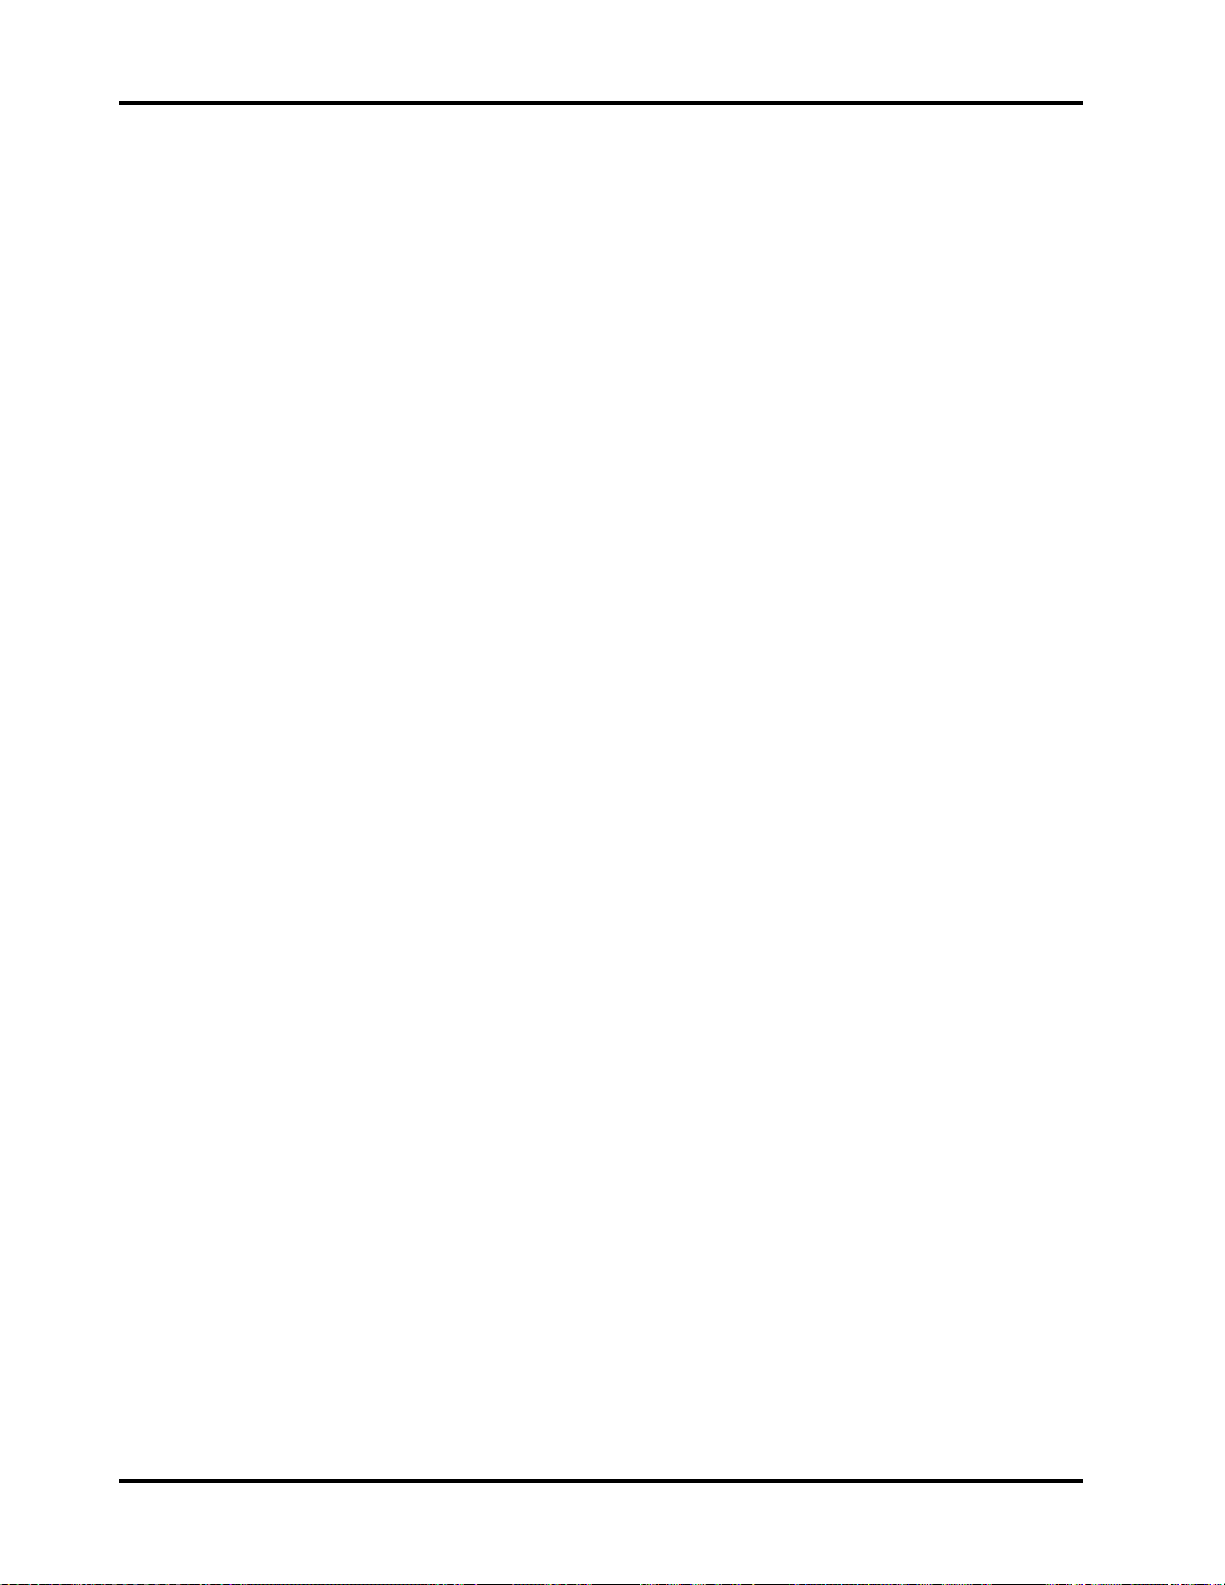
The drive assembly housing, or Head-Disk Assembly (HDA) consists of a die-cast
aluminum base on which is mounted a die-cast aluminum cover. Both the base
and the cover are coated with a special material designed to seal out
contaminants which might degrade head and media reliability. A gasket seals
the joint between the base and cover to retard the entry of moisture and
environmental contaminants from the assembly.
This assembly, the head-disk assembly, contains an integral 0.3 micron filter,
which maintains a clean environment. Critical drive components are contained
within this contaminant-free environment. Figure 1-2 shows the HDA and the
major assemblies contained within it:
Figure 1-2
Head-Disk Assembly
Disk (1 of 4)
Disk
Spacer (1 of 3)
Filter
Top Cover
Disk Clamp
Gasket
Preamplifier/
Flex Circuit
Assembly
Head-Stack
Assembly
Actuator
Magnet
Assembly
Spindle Motor
Base Assembly
1060-1-2
Technical Reference Manual Page 5
Page 14
Chapter 1 Overview of the Drives
Drive Motor and Spindle
A brushless DC direct-drive motor assembly is mounted on the drive’s base. The
motor rotates the drive’s spindle at 5400 RPM. The motor/spindle assembly is
dynamically balanced to provide minimal mechanical runout to the disks. A
dynamic brake is used to provide a fast stop to the spindle motor and return the
heads to the landing zone when power is removed.
Head Positioning Mechanism
The read/write heads are supported by a mechanism coupled to a rotary voice
coil actuator.
Read/Write Heads and Disks
Data is recorded on 95mm diameter disks through 3370-type 50% nano-slider
thin film heads with transverse pressure contour (TPC) air bearing surfaces.
The TPC air bearing surface allows the head to fly at a uniform height
regardless of radial position. This improves data reliability and allows the aerial
density to be more uniform with radius. The drive contains four sputtered thin
film disks with eight data surfaces and eight read/write heads.
At power-down, the heads are automatically retracted to the inner diameter of
the disk and are latched and parked on a landing zone that is inside the data
tracks.
Data and Power Connections
Data and power connections to the drive are differ between the drive models.
Refer to chapter 4 for information regarding a specific model's requirements.
Electrical Design Features
Integrated Circuit
A single integrated circuit (IC) is mounted within the sealed hard drive assembly
in close proximity to the read/write heads. The IC provides head selection, read
pre-amplification, and write drive circuitry.
Circuit Board
The drive’s dual-microprocessor-controlled circuit board provides the remaining
electronic functions, which include:
• read/write circuitry
• rotary actuator control
• interface control
• spin speed control
• auto-park
• power management
The background processor is a 16-bit Motorola 68HC16. The entire data path
between the serializer-deserializer and the interface chip, including the buffer
Page 6 Filepro CFP1060E/CFP1060S/CFP1060W
Page 15
Overview of the Drives Chapter 1
(cache) is 16 bits wide to provide high data throughput. The "Catalina" SCSI
interface chip manages a 16-bit to 8-bit conversion prior to transacting data over
the SCSI bus for 8-bit narrow SCSI applications.
The data buffer (cache) utilizes a 256K x 16 Dynamic RAM. Data path integrity
is ensured by using a 4-byte CRC which is appended to the data upon receipt by
the Catalina. This CRC is verified by the "Indy" buffer manager when the data
is taken out of the buffer to be written to the disk and the CRC is written with
the data. A typical sector data field consists of 512 bytes of data, 4 bytes of CRC
and 11 bytes of Error Detection And Correction (EDAC) code. The same CRC
checks are performed during an outbound process and the CRC is stripped from
the data prior to sending it to the Host.
The SCSI interface functions are managed by a 8-bit Motorola 68HC11
microprocessor. Low SCSI transaction overhead is maintained by automating
common SCSI bus phase sequencing using a state machine in the Catalina chip.
Read/Write Channel
The Read/Write channel, in addition to the preamplifier discussed earlier,
consists of three integrated circuits:
• Pulse Detector
• Data Separator
• Time base
Firmware
The drive’s firmware can be considered in two parts. The first part principally
resides in the ROM for the 68HC16 background processor. This processor is
responsible for:
• starting the spindle motor and maintaining precise rotational speed
• controlling track following and actuator motion during seeking
• managing background R/W activity
• power management
• monitoring the overall health of the drive.
The interface processor's control microcode resides in both ROM and RAM. The
RAM portion of the microcode can be upgraded in the field with using software.
Additional information regarding the RAM code can be found in Chapter 3, page
23. The interface processor firmware functions include:
• reporting drive status and error conditions to the host
• manage operating parameters for the drive
• parsing the Command Descriptor Block and checking for illegal fields
• converting the LBA to CHS and initiating read and write operations to the
background processor
• defect management
• serial port communications
Technical Reference Manual Page 7
Page 16
Chapter 1 Overview of the Drives
Since parsing/decoding of commands and execution of the Read/Write functions
are handled by separate processors, command execution can be overlapped in
multiple initiator or Tagged Command Queuing environments. Functions such
as seek re-ordering and command coalescing can also be overlapped when the
drive is operating with a host environment capable of supporting Tagged
Command Queuing.
For more information on the drive’s interface implementation and command set,
refer to the Ninth Generation SCSI Interface Manual.
Page 8 Filepro CFP1060E/CFP1060S/CFP1060W
Page 17
Specifications
2
Specifications in this Chapter
This chapter provides the following specifications for the drive:
• drive capacity
• physical configuration
• performance characteristics
• read/write characteristics
• reliability
• power requirements
• environmental tolerances
• safety standards
• physical characteristics
Technical Reference Manual Page 9
Page 18
Chapter 2 Specifications
Drive Capacity
Formatted Capacity
• CFP1060E: 1,060.33MB
• CFP1060S: 1,060.33MB
• CFP1060W: 1,060.33MB
*1MB is equal to 106 or 1,000,000 bytes
Physical Configuration
Specification:
Disk Type
Head Type
Actuator Type
Number of Disks
Data Surfaces
Data Heads
Servo
Tracks per Surface
Track Density @ 0
Bytes per Block
Blocks per Drive (physical)
*
°Skew
CPF1060E
CFP1060S
CFP1060W:
Sputtered Thin film
Thin Film - TPC
Rotary Voice-Coil
4
8
8
Embedded
2756
3150 TPI
512-520, 1024-1040
2,074,880
Physical Configuration per Zone
Data Rate
(Mbits/sec)
Zone 0 (OD) 55.072 884 111
Zone 1 51.304 316 103
Zone 2 48.889 214 99
Zone 3 47.246 147 95
Zone 4 44.242 250 89
Zone 5 41.818 206 84
Zone 6 37.460 361 79
Zone 7 34.242 275 69
Zone 8 (ID) 31.111 103 63
* The physical track configuration contains one spare sector per track.
Page 10 Filepro CFP1060E/CFP1060S/CFP1060W
Data Tracks per
Zone per Surface
User Sectors
per Track *
Page 19
Specifications Chapter 2
Performance Characteristics
Seek Times (typical)*
• Track to Track: 2.0 msec
• Average (read/write): 9.0/9.5 msec
**
• Full Track: 16 msec
* The timing is measured from the time the last byte of the command descriptor block is
written to the time seek is initiated by the drive operating at nominal DC input
voltage and nominal operating temperature.
** The average seek time is determined by averaging the seek time for a minimum of
1000 seeks of random length over the surface of the disk.
Average Latency
• 5.55 milliseconds
Rotation Speed (+0.1%)
• 5400 RPM
Controller Overhead
• 20 µsec
Start Time(Power Up)*
• 0 RPM to Ready
− Typical: 12 seconds
− Maximum: 20 seconds
* These numbers assume spin recovery is not invoked. If spin recovery is invoked, the
maximum could be 40 seconds. Briefly removing power can lead to spin recovery
being invoked.
Stop Time at Power Down
• Typical: 7 seconds
• Maximum: 10 seconds
Interleave
• 1:1
Technical Reference Manual Page 11
Page 20
Chapter 2 Specifications
Read/Write Characteristics
Recording Method
• 1,7 RLL code
Recording Density (maximum)
• 65,131 bits per inch
Flux Density (maximum)
• 48,848 flux reversals per inch
Host Interface Characteristics
Command Set
• SCSI-2 (refer to the Ninth Generation SCSI Technical Reference Manual for
command implementation)
Data Transfer Rate
• To/from Buffer, synchronous narrow: 10.0 MByte/second
• To/from Buffer, synchronous wide: 20.0 MByte/second
Maximum Synchronous Transfer Offset:
• 15 bytes/words
Maximum Tagged Command Queue Depth:
• 32 commands
Buffer Size:
• 512 KB, segmentable
Page 12 Filepro CFP1060E/CFP1060S/CFP1060W
Page 21
Specifications Chapter 2
Reliability
Data Reliability
14
• < 1 non-recoverable error in 10
Component Design Life
• 5 years
Start/Stop cycles
• 10,000 minimum
Mean Time Between Failures:
• 500,000 power-on hours*
* Projected MTBF based on comparison of similar Conner products
Mean Time to Repair
bits read
• 10 minutes, typical
Preventive Maintenance
• None
Technical Reference Manual Page 13
Page 22
Chapter 2 Specifications
Power Requirements (Typical)
+12V DC
Mode
Read/Write
Seek (100%)
Seek (30%)
Idle
Standby
Spin-up
1
Typical conditions are both voltages at nominal value, room temperature (25° C)
ambient to the drive without terminators installed. Maximum power is when the
supply voltage is at the worst case condition.
(typical1)
280 mA 685 mA 6.8 W 7.5 W
700 mA 640 mA 11.6 W 13.3 W
310 mA 490 mA 6.2 W 7.0 W
270 mA 510 mA 5.8 W 6.3 W
9 mA 475 mA 2.5 W 2.7 W
1.6 A 800 mA n/a 1.7 A
+5V DC
(typical)
Power
(typical)
Minimum/Maximum Voltage:
• +5V: +5%
• +12V: +5%
Maximum Peak-to-Peak Allowable Noise
(DC to 1 Mhz: equivalent resistive load):
• +5V: 2%
• +12V: 1%
Power
(maximum)
Page 14 Filepro CFP1060E/CFP1060S/CFP1060W
Page 23
Specifications Chapter 2
Environmental Tolerances
Temperature:
• Operating: 5° to 55° C
• Non-operating: -40° to 60° C
• Thermal Gradient: 20°
Relative Humidity (non-condensing):
• Operating: 5 to 95%
• Non-operating: 5 to 95%
• Maximum Wet Bulb: 29°C
Altitude (relative to sea level):
• Operating: -200 to 10,000 feet
• Non-operating: 40,000 feet (maximum)
• Altitude Gradient: 1,000 feet/minute
Shock (half-sine pulse, 11 ms duration):
• Operating: 10G peak without non-recoverable errors
• Non-operating: 75G without non-recoverable errors
C per hour maximum
Vibration (swept-sine, one octave per minute):
• Operating
− 5 - 32 Hz: 0.010 inch displacement; peak to peak
− 32 - 400 Hz: 0.5G without non-recoverable errors
• Non-operating
− 5 - 28 Hz: 0.020 inch displacement; double amplitude
− 28 - 400 Hz: 4G peak
Magnetic Field:
• The disk drive will meet its specified performance while operating in the
presence of an externally-produced magnetic field under the following
conditions:
Field Frequency Intensity
DC
to 700 Khz
700 Khz to 1.5 Mhz
Acoustic Noise:
• The acoustic level will not exceed 37 dBA sound pressure or 43 dBA sound
power in Idle Mode at a distance of 1 meter from the drive.
6 gauss
7 milligauss
3 milligauss
Technical Reference Manual Page 15
Page 24
Chapter 2 Specifications
Safety Standards
The drive is designed to comply with relevant product safety standards,
including:
• UL 478, 5th edition, Standard for Safety of Information Processing and
Business Equipment
• UL 1950, Standard for Safety of Information Technology Equipment
• CSA 22.2 #220, Information Processing and Business Equipment
• CSA 22.2 #950, Safety of Information Technology Equipment
• IEC 380, Safety of Electrically Energized Office Machines
• IEC 950, Safety of information Technology Equipment Including Electrical
Business Equipment
• VDE 0805, VDE 0805 TIEL 100, and VDE 0806
• Complies with FCC Class B, Part 15, Subpart J
Page 16 Filepro CFP1060E/CFP1060S/CFP1060W
Page 25
Specifications Chapter 2
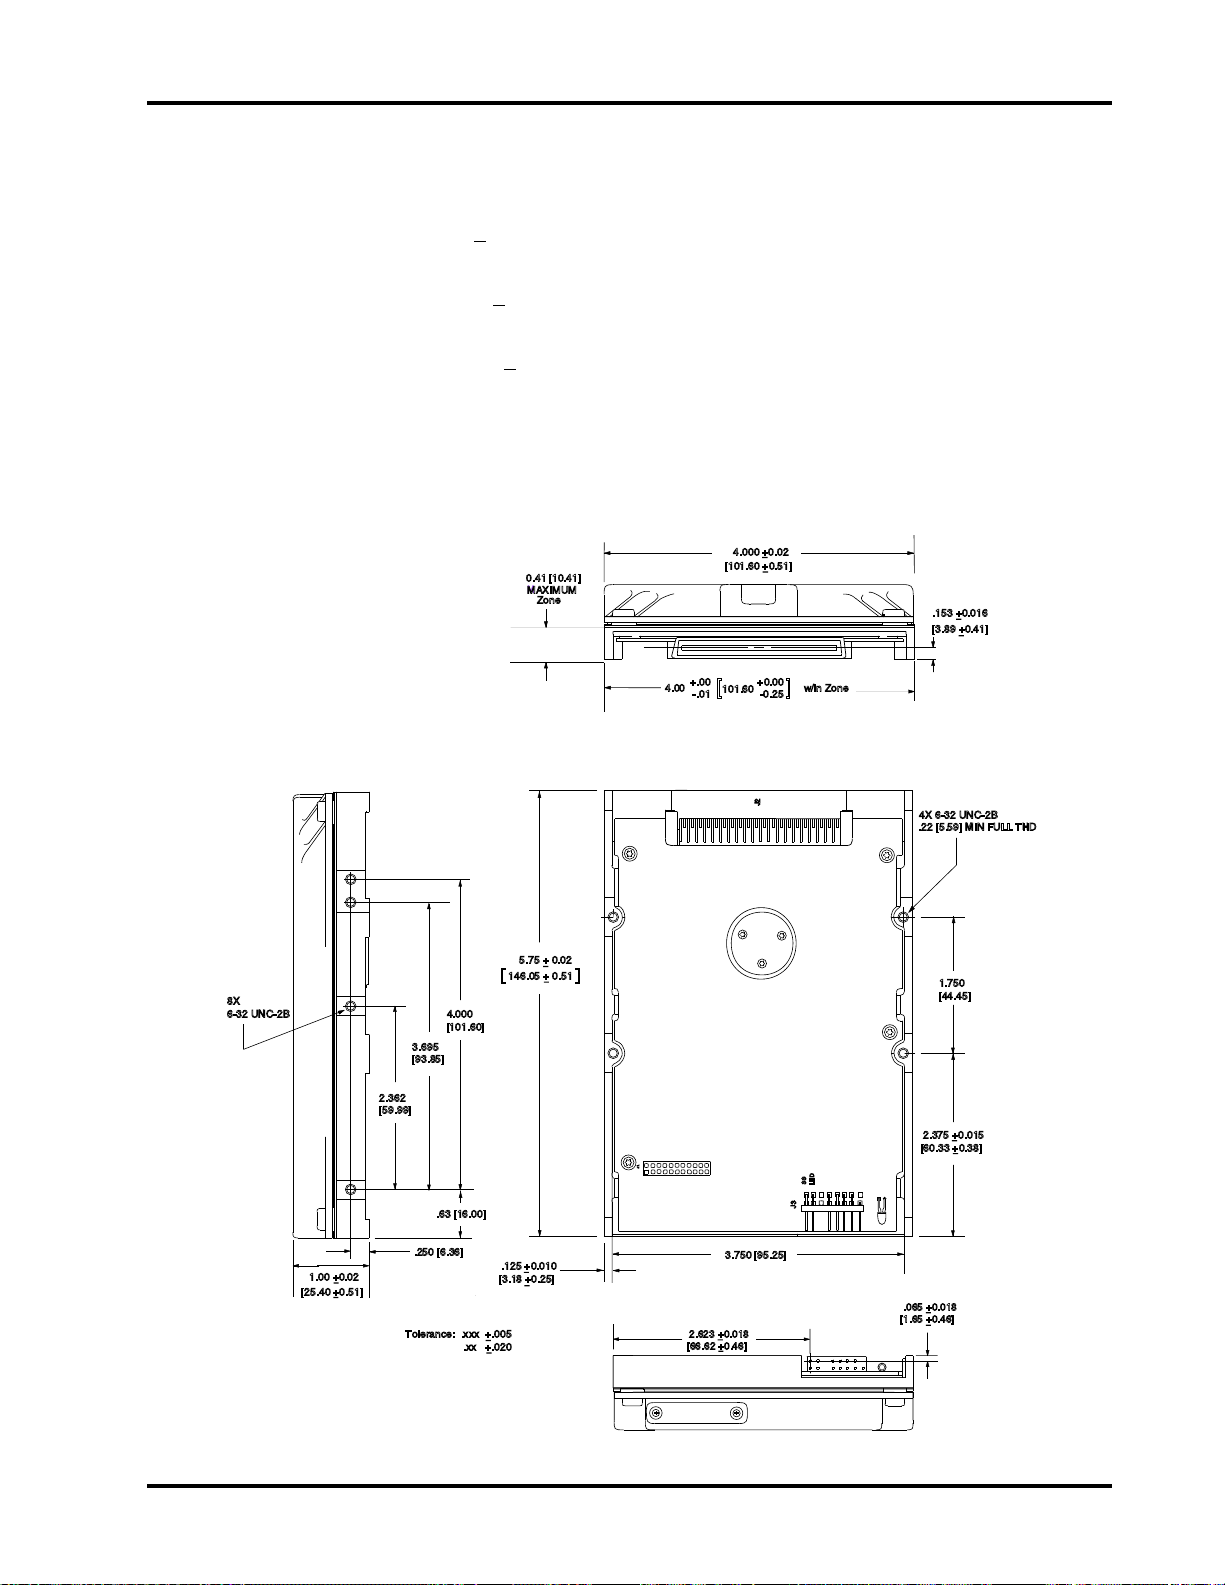
Physical Characteristics - CFP1060E
Height:
• 1.0 inch + .020
Width:
• 4.0 inches + .020
Depth:
• 5.75 inches + .020
Weight:
• 1.3 pounds
Figure 2-2
The Drive’s Physical Dimensions
4.000 +0.02
0.41 [10.41]
MAXIMUM
Zone
[101.60 +0.51]
.153 +0.016
[3.89 +0.41]
8X
6-32 UNC-2B
1.00 +0.02
[25.40 +0.51]
3.695
[93.85]
2.362
[59.99]
.63 [16.00]
.250 [6.36]
Tolerance: .xxx +.005
4.000
[101.60]
.xx +.020
5.75 + 0.02
146.05 + 0.51
[ ]
.125 +0.010
[3.18 +0.25]
+.00
4.00
-.01
J1
2.623 +0.018
[66.62 +0.46]
+0.00
101.60
[ ]
-0.25
J2
3.750 [95.25]
w/in Zone
LED
SS
J3
4X 6-32 UNC-2B
.22 [5.59] MIN FULL THD
1.750
[44.45]
2.375 +0.015
[60.33 +0.38]
.065 +0.018
[1.65 +0.46]
1060-2-2
+
+
Technical Reference Manual Page 17
Page 26
Chapter 2 Specifications
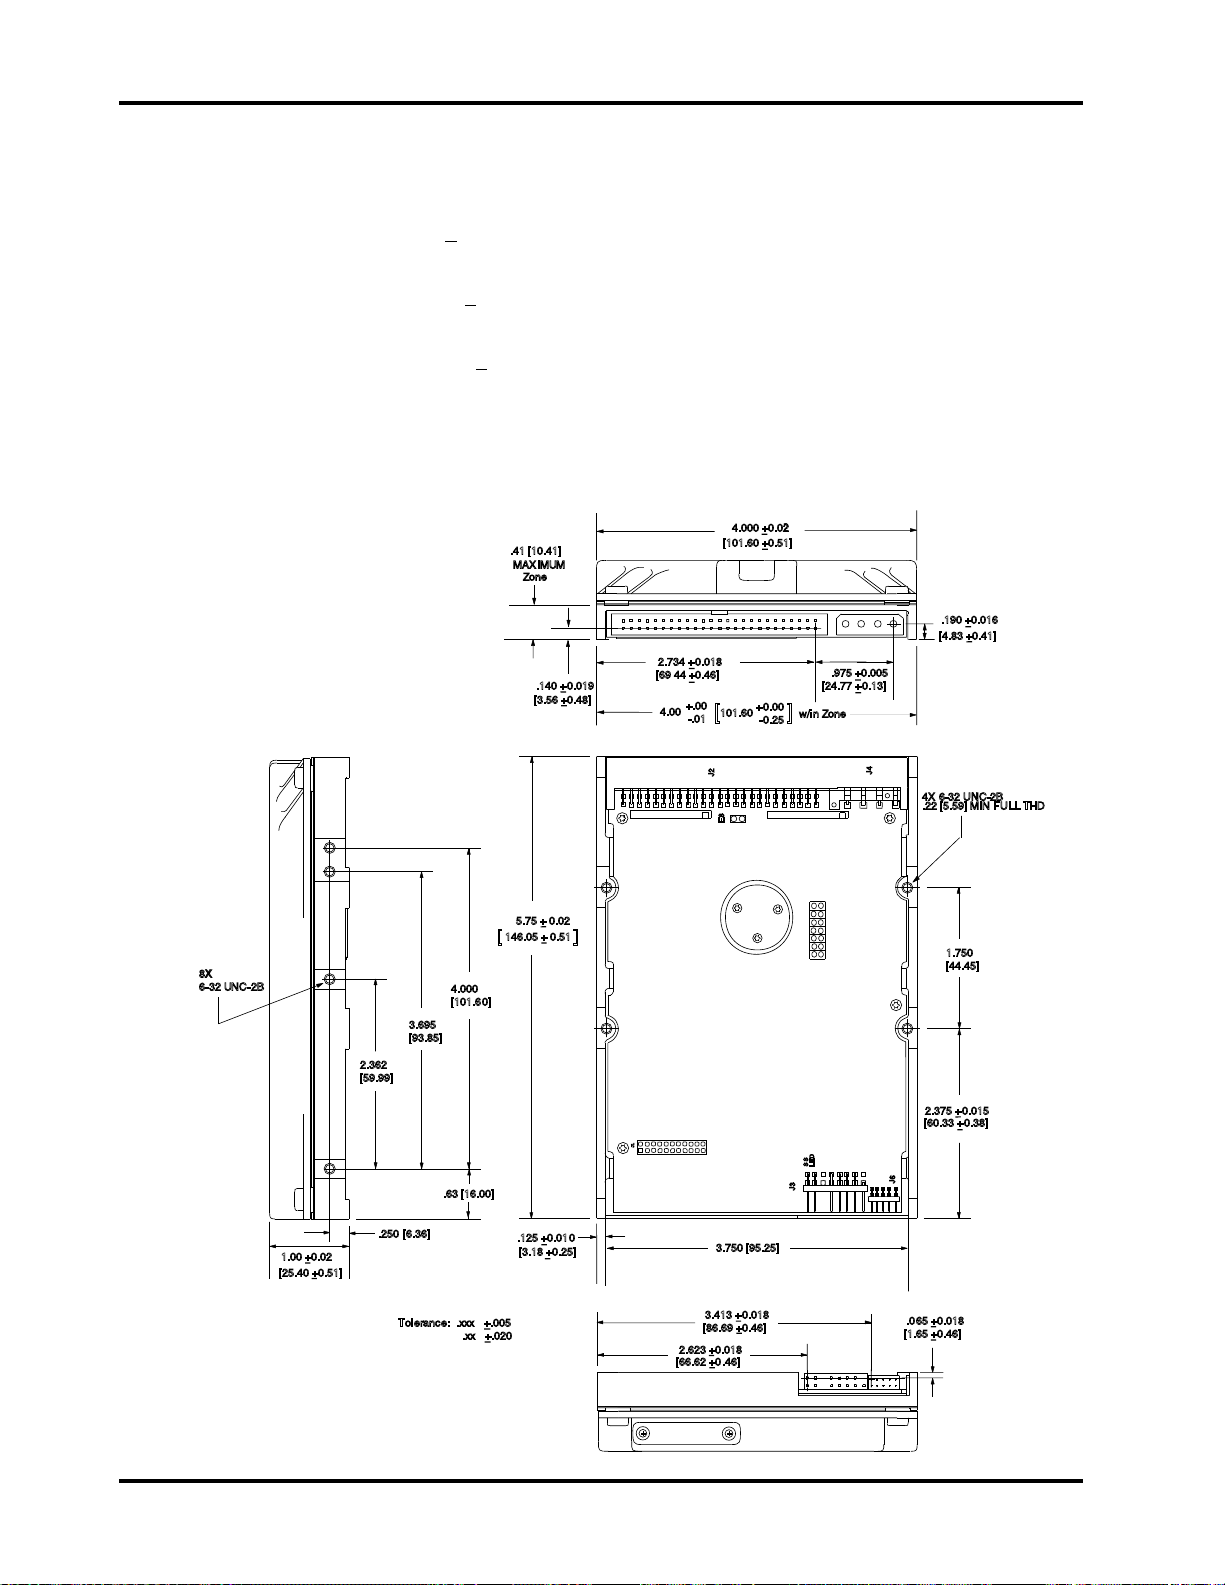
Physical Characteristics - CFP1060S
Height:
• 1.0 inch + .020
Width:
• 4.0 inches + .020
Depth:
• 5.75 inches + .020
Weight:
• 1.3 pounds
Figure 2-3
The Drive’s Physical Dimensions
4.000 +0.02
+.00
101.60
[ ]
-.01
[101.60 +0.51]
+0.00
-0.25
[24.77 +0.13]
w/in Zone
.975 +0.005
.190 +0.016
[4.83 +0.41]
.41 [10.41]
MAXIMUM
Zone
.140 +0.019
[3.56 +0.48]
2.734 +0.018
[69 44 +0.46]
4.00
8X
6-32 UNC-2B
1.00 +0.02
[25.40 +0.51]
3.695
[93.85]
2.362
[59.99]
.250 [6.36]
Tolerance: .xxx +.005
.xx +.020
4.000
[101.60]
.63 [16.00]
5.75 + 0.02
146.05 + 0.51
[ ]
.125 +0.010
[3.18 +0.25]
J1
J2
E8
3.750 [95.25]
3.413 +0.018
[86.69 +0.46]
2.623 +0.018
[66.62 +0.46]
J4
4X 6-32 UNC-2B
.22 [5.59] MIN FULL THD
1.750
[44.45]
2.375 +0.015
[60.33 +0.38]
SS
LED
J3
J6
.065 +0.018
[1.65 +0.46]
+
1060-2-3
+
Page 18 Filepro CFP1060E/CFP1060S/CFP1060W
Page 27
Specifications Chapter 2
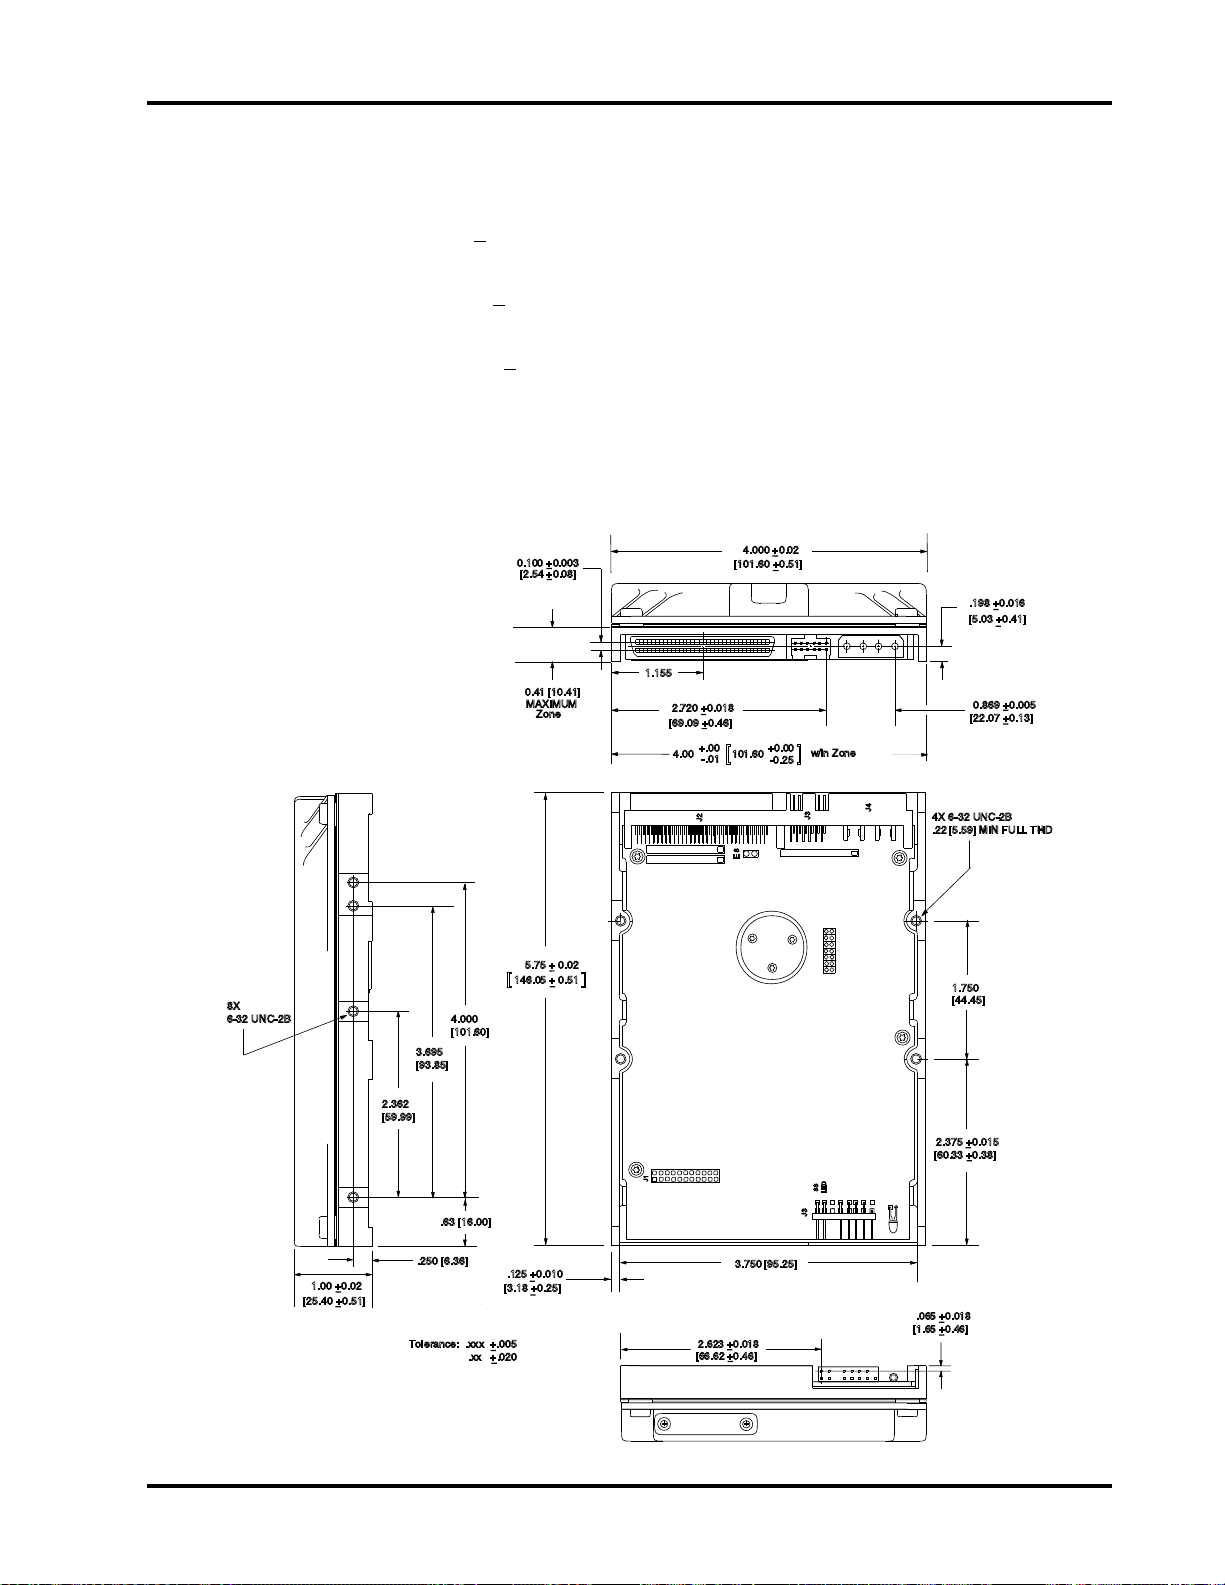
Physical Characteristics - CFP1060W
Height:
• 1.0 inch + .020
Width:
• 4.0 inches + .020
Depth:
• 5.75 inches + .020
Weight:
• 1.3 pounds
Figure 2-4
The Drive’s Physical Dimensions
8X
6-32 UNC-2B
2.362
[59.99]
3.695
[93.85]
4.000
[101.60]
.63 [16.00]
0.100 +0.003
[2.54 +0.08]
0.41 [10.41]
MAXIMUM
Zone
5.75 + 0.02
146.05 + 0.51
[ ]
1.155
J1
2.720 +0.018
[69.09 +0.46]
+.00
4.00
-.01
J2
4.000 +0.02
[101.60 +0.51]
+0.00
101.60
[ ]
-0.25
E8
w/in Zone
J3
SS
LED
J3
.198 +0.016
[5.03 +0.41]
0.869 +0.005
[22.07 +0.13]
J4
4X 6-32 UNC-2B
.22 [5.59] MIN FULL THD
1.750
[44.45]
2.375 +0.015
[60.33 +0.38]
1.00 +0.02
[25.40 +0.51]
1060-2-4
.250 [6.36]
Tolerance: .xxx +.005
.xx +.020
.125 +0.010
[3.18 +0.25]
+
3.750 [95.25]
2.623 +0.018
[66.62 +0.46]
.065 +0.018
[1.65 +0.46]
+
Technical Reference Manual Page 19
Page 28
Chapter 2 Specifications
Page 20 Filepro CFP1060E/CFP1060S/CFP1060W
Page 29
How the Drive Operates
3
Functions of the Drive
This chapter describes certain operational aspects of the drive, including
discussions of:
• drive operational modes
• error correction
• read error recovery
• downloadable microcode
• buffer management
Drive Operational Modes
The drive operates in the following modes:
•• Read/Write Mode occurs when data is read from or written to the disk.
•• Seek Mode (100%) occurs when the actuator is in motion.
•• Seek Mode (30%) is based on 1/3 stroke seeks with a 30% seek duty cycle.
•• Idle Mode occurs when the drive is not reading, writing, or seeking. The
motor is up to speed and the Drive Ready condition exists. The actuator is
residing on the last-accessed track.
•• Standby Mode occurs when the motor is stopped and the actuator is
latched in the landing zone. The drive will enter Standby mode after poweron reset if the Disable Spin jumper is installed or the DSPN bit in MODE
SELECT page 0 is set. A STOP UNIT command will also place a drive into
Standby Mode. The drive will spin up and go into Idle mode when a START
UNIT command is issued or on a timed basis by SCSI ID if the SDLY bit is
set in MODE SELECT page 0. Refer to the MODE SELECT and MODE
SENSE commands in the Ninth Generation SCSI Interface Manual for
additional details.
•• Spin-Up Mode occurs while the drive's spindle motor is being spun up to
speed after initial power on or after exiting Standby Mode.
Technical Reference Manual Page 21
Page 30
Chapter 3 How the Drive Operates
Error Correction
The drive uses a Reed-Solomon code to perform error detection and correction.
For each 512-byte block, the software error correction polynomial is capable of
correcting:
• one error burst of up to 22 bits in length
• two error bursts each up to 11 bits in length
Single bursts of 11 bits or less are corrected on the fly (OTF) with no
performance degradation. A larger defect up to 22 bits in length or a second
defect of up to 11 bits in length is corrected using firmware within one latency
period, after all retries have been exhausted.
The code has the following error detection capability:
• three error bursts each up to 11 bits in length
• a single burst of up to 51 bits in length
Read Retry Operations
The drive retries data field read operations in the following sequence if it detects
an error which cannot be corrected on-the-fly. The default retry algorithm
repeats eight times for a total of 128 retries or until the data is recovered.
1. Initial read
2. First retry
3. Read retry with data threshold offset +1
4. Read retry with data threshold offset -1
5. Read retry with data window offset +1
6. Read retry with data window offset -1
7. Write Spash
8. Read retry with data threshold offset +2
9. Read retry with data threshold offset -2
10. Read retry with data window offset +2
11. Read retry with data window offset -2
12. Normal read retry
13. Read retry with servo offset +8%
14. Read retry with servo offset -8%
15. Normal read retry
16. Software (2-burst) EDAC correction attempt
If retries are disabled, the drive retries the operation one time before it reports
an error.
Page 22 Filepro CFP1060E/CFP1060S/CFP1060W
Page 31
How the Drive Operates Chapter 3
Downloadable Microcode
The SCSI interface code is split into two parts which are designated as ROM or
RAM code. The ROM code contains the basic SCSI operating code and code to
support commands such as INQUIRY, TEST UNIT READY, REQUEST SENSE,
START/STOP UNIT, etc., which may have to be responded to prior to the drive
being in a ready state. The part of the interface code referred to as RAM code
resides on an area of the disk which is reserved to the drive and is not directly
accessible through the interface. This code is referred to as RAM code because it
is read from the disk and is loaded into static RAM after power is applied to the
disk, as soon as the drive is able to read from the disk.
The RAM code consists of a resident portion which is loaded after a Power On
Reset. Two different versions of RAM code overlays also reside on the disk. The
read look ahead code overlay is the default and is loaded into RAM during the
initial power-on. If a Queue Tag message is received by the drive, the drive will
execute the command and while it is in Status Phase, will read the Queuing code
overlay from the disk and load it into the RAM. This operation takes about 600
milliseconds, after which the drive will complete the command by sending the
status. The drive will continue to operate with Queuing code residing in RAM
until the next Power On Reset.
Refer to the next section for a discussion of the buffer management implications
for the different RAM codes.
The RAM code may be upgraded on the disk via the factory serial port or
through the interface using the WRITE BUFFER command. Refer to the
WRITE BUFFER command in the Ninth Generation SCSI Interface Manual for
a discussion of the procedure.
Technical Reference Manual Page 23
Page 32
Chapter 3 How the Drive Operates
Buffer Management and Command Execution
The drive contains a 512Kbyte segmentable buffer which is dynamically
configured to adapt to the particular drive configuration or operating
environment.
Read Look Ahead Code
The Read Retention RAM code executes commands sequentially as they are
received from the initiator(s). Commands from multiple initiators may be
queued and overlapped so that the subsequent command can be parsed while the
current command is being executed.
The drive's 512K byte buffer is configured as four segments. These segments
allow the drive to cache sequential data from four separate areas on the disk.
This can significantly improve performance in any environment in which
multiple disk files are kept open simultaneously and operated upon in some
interleaved fashion.
The Look-Ahead RAM code segments the 512 KB buffer into four 130,548 byte
(FD
blocks) segments. The remainder of the RAM is used by the
H
microprocessor as a scratch pad area and for non read or write data information
transfers. The buffer block size is equal to the data block size (typically 512 B)
plus the 4 bytes of buffer CRC appended to each block. (refer to the Electrical
Design Feature section in Chapter 1 for a description of the buffer CRC).
Buffer operations default on Power-up to Read Look Ahead enabled and Write
Caching disabled. MODE SELECT page 8, byte 2, bit 0 (RCD), when set to one
disables the read look-ahead cache function and bit 2 (WCE), when set to one
enables write cache. In addition, MODE SELECT page 8, byte 3 contains two
fields which control the retention priority for reads and writes. Refer to the
Ninth Generation Disk Drive SCSI Interface Manual for additional details.
When a read command is received by the disk drive, the cache tables are
searched to determine if the requested data is contained in any of the four cache
segments (a cache hit). If there is no cache hit, the Least Recently Used (LRU)
segment is selected and a read from disk is initiated into that segment which is
now considered the Active Segment. The retention of data already transferred to
the host and read look ahead in the Active Segment buffer is controlled by the
state of the Read Retention Priority.
Page 24 Filepro CFP1060E/CFP1060S/CFP1060W
Page 33
How the Drive Operates Chapter 3
Read Retention On (Read Retention Priority = 0 or F):
The interface processor initiates a full segment read of 253 sectors (FD
blocks)
H
to the background processor. There are three different situations which would
be considered a cache hit on a subsequent read.
• Full: All of the data requested is transferred from the buffer segment and
retained.
• Partial: Some but not all of the data is cached in a buffer segment. If the
cached data is in the Active Segment and the remaining data is part of the
full segment read, the drive will transfer the requested data from the buffer
as the background process fills it. If the cached data is in the Active
Segment but the remaining data is not part of the full segment read, the
drive will turn off read retention until the next Active Segment miss occurs
and issues a new read (forever) to the background process. This allows the
drive to adapt to long sequential reads even in read retention mode. If the
data is part of an Inactive Segment, a new full segment read is initiated,
making this the Active Segment.
• Potential: If none of the data is in the Active Segment, but is part of the
full segment read, the drive will transfer the data as it becomes available.
Read Retention Off (Read Retention Priority = 1): The interface processor
initiates a "read forever" command to the background processor and the buffer
segment is treated as a circular buffer which is back filled as sectors are
transferred to the host. There are three different situations which would be
considered a cache hit on a subsequent read.
• Full: All of the requested data is cached in a buffer segment. If it is the
Active Segment, the data will be transferred to the host and refilled with
next sequential data. If the data in an Inactive Segment, the data is
transferred to the host and retained.
• Partial: This is when some, but not all of the data is cached in a buffer
segment. If the data is in the Active Segment, data is transferred to the host
as the background process fills the buffer and the "read forever" is allowed to
refill the buffer. If the data in an Inactive Segment, the cached data is
transferred and a new read operation is initiated for the remaining data,
making this the Active Segment.
• Potential: None of the data is cached. The active segment is checked and if
the requested data is within 63 sectors of being read, the drive will allow the
"read forever" operation to continue and the data is transferred to the host
when it is available.
Technical Reference Manual Page 25
Page 34
Chapter 3 How the Drive Operates
Write Caching
Write Caching allows multiple write commands operating on sequential blocks to
be written to the medium without losing a motor revolution between commands.
Write caching is enabled by setting the WCE bit in MODE SELECT page 8 to
one. The WCE bit is only valid while the Read Look Ahead code is loaded. The
WCE bit is ignored when the Tagged Command Queuing code is in RAM because
write coalescing will be active.
The drive will send good status and command complete following the data out
phase of a cached write command. The drive will cache writes when the
following conditions are met:
• Two or more write commands (Op Code 0A
or 2AH) execute consecutively
H
without an intervening command.
• The write commands address consecutive logical block ranges.
• At least one logical block of data has been received in the buffer from the
second write command in time to allow the medium to be written before an
additional spindle revolution would be required.
• Both writes are from the same initiator.
• Neither write is a linked command.
If the drive encounters an error during a cached write operation, the drive will
respond by:
If AWRE (MODE SELECT page 01
) is 0: the drive will report a CHECK
H
CONDITION on the next command and the response from a REQUEST SENSE
will be a deferred error. (Asynchronous event notification is not supported by
this drive.) Refer to the Ninth Generation SCSI Interface Manual for additional
details.
If AWRE (MODE SELECT page 01
) is set to 1: the drive will attempt to
H
dynamically reassign the block of data and complete the operation. If the
reassignment fails, the drive will continue to reassign the block until all the
space in the grown defect list is filled (147 sectors, maximum).
Page 26 Filepro CFP1060E/CFP1060S/CFP1060W
Page 35
How the Drive Operates Chapter 3
Tagged Command Queuing
The drive, operating using the Tagged Command Queuing code, can queue up to
32 commands. Commands in the queue which involve seeks are re-ordered
using a Scan (elevator seek methodology). Read and Write commands are
coalesced (combined into a single operation to the background processor) to
minimize inter processor communication overhead and reduce mechanical
motion.
Seek Re-ordering
Seeks are re-ordered using the Scan or what is sometimes referred to as the
elevator seek method. Seeks already in the queue are re-ordered so they can be
executed sequentially on a sweep toward the inner diameter (ID) or the outer
diameter (OD) of the disk. Any new seeks entering the queue ahead of the
sweep is ordered for execution during the current sweep. Any new seeks
entering the queue behind the current sweep are held for re-ordering during the
reverse sweep. When there are no more commands in the queue ahead of the
current sweep, the direction of the sweep is reversed.
Seek re-ordering is controlled by Message Code (Simple, Head of Queue or
Ordered Queue) during the Message Phase. Re-ordering of seeks issued with a
Simple Queue Tag message may also be restricted using the Queue Algorithm
Modifier bits in MODE SELECT page 0A
. Refer to the Ninth Generation SCSI
H
Interface Manual for additional information on Messages and MODE SELECT
page 0A
.
H
Buffer Management
The 512K byte buffer is treated by the queuing code as two 240KB buffers (F0
H
sectors) to maximize coalescing. Look ahead reads are performed by the drive
when there are no commands in the queue awaiting execution. Look ahead
reads are not performed when there are commands in the queue since another
command will be waiting for execution as soon as the current command
completes and because the queue affords pre-knowledge of subsequent
commands instead of having to anticipate them.
Sequential read or write commands are coalesced into single commands to the
background processor. On a read operation, the data associated with each queue
tag is transmitted to the host as the buffer is filled by the background processor.
On write operations, the drive will connect to the initiator(s), transmit the data
into the buffer and disconnect; coalescing sequential data in the buffer before
initiating the write to the background processor. The drive will reconnect with
each of the writes, using the queue tags, completing the command after the data
has been written to the disk. This operation provides the performance of write
caching without the exposure of completing the command prior to writing the
data to the disk.
Technical Reference Manual Page 27
Page 36
Chapter 3 How the Drive Operates
Page 28 Filepro CFP1060E/CFP1060S/CFP1060W
Page 37
Installing the Drive
4
Take These Precautions
Installing the Drive
To install the drive, you must:
To protect your equipment from electrostatic damage,
perform the installation at a static-safe workstation. If one is
not available, follow these guidelines:
1. Work in an uncarpeted area.
2. Before removing the equipment from its anti-static bag,
discharge static electricity by touching your computer's
metal chassis (or any other grounded object) while
touching the anti-static bag.
3. Do not touch circuit boards unless instructed to do so.
0170
• set the drive’s jumpers, if desired
• attach a data cable to the drive
• attach power to the drive
• mount the drive
These procedures differ between the various drive models.
Technical Reference Manual Page 29
Page 38
Chapter 4 SCSI Physical Characteristics
Installing a CFP1060E
The following paragraphs describe the installation procedure for a 16-bit Single
Connector Attachment (SCA) interface, model CFP1060E drive.
Setting the Drive's Jumpers - 1060E
There are no jumpers to set on the model CFP1060E drive since all the
necessary control signals are on the SCA connector. This drive is intended for
applications where the drive is configured at the interface when the drive is
plugged into the interface connector.
Setting the SCSI Bus Address - CFP1060E
The SCSI bus ID of the drive is set by grounding the Interface bus signals shown
below in Table 4-4.
Table 4-4
Setting the SCSI ID
SCSI ID SCSI ID(0) SCSI ID(1) SCSI ID(2) SCSI ID(3)
0
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
Open Open Open Open
Ground Open Open Open
Open Ground Open Open
Ground Ground Open Open
Open Open Ground Open
Ground Open Ground Open
Open Ground Ground Open
Ground Ground Ground Open
Open Open Open Ground
Ground Open Open Ground
Open Ground Open Ground
Ground Ground Open Ground
Open Open Ground Ground
Ground Open Ground Ground
Open Ground Ground Ground
Ground Ground Ground Ground
Page 30 Filepro CFP1060E/CFP1060S/CFP1060W
Page 39
SCSI Physical Characteristics Chapter 4
Disabling Spin-Up at Power On - CFP1060E
Spin up upon application of power to the drive can be disabled by grounding the
RMT_START line on the interface. Disabling spin up on application of power
can also be enabled by setting the DSPN bit in MODE SELECT page 00
(Operating Parameters). The Host must issue a START UNIT command to
cause the drive to spin up. Refer to the Ninth Generation SCSI Technical
Reference Manual for additional information regarding the MODE SELECT and
START/STOP UNIT commands.
Table 4-5
Disabling Spin Up at Power On
H
RMT_START DSPN Result
Ground 0 Spin Disabled
Ground 1 Spin Disabled
Open 0 Spin up on Power On
Open 1 Spin Disabled
Delaying Spin Up at Power On - CFP1060E
Grounding the DLYD_START signal on the interface delays spin up on power-up
by the value of the drive's SCSI ID multiplied by 4 seconds (i.e. SCSI ID 4 will
delay 16 seconds). Delaying spin up on application of power can also be enabled
by setting the SDLY bit in MODE SELECT page 00
Refer to the Ninth Generation SCSI Technical Reference Manual for additional
information regarding the MODE SELECT command.
Table 4-6
Delaying Spin Up at Power On
DLYD_START SDLY Result
Ground 0 Spin Delayed
Ground 1 Spin Delayed
Open 0 Spin up on Power On
Open 1 Spin Delayed
Cabling the Drive - CFP1060E
The drive is intended for direct backplane connection to the SCA connector
rather than through cabling.
(Operating Parameters).
H
Attaching Power to the Drive - CFP1060E
The drive is powered through the SCA connector and is intended for direct
backplane connection rather than through cabling.
Technical Reference Manual Page 31
Page 40
Chapter 4 SCSI Physical Characteristics
Mounting the Drive - CFP1060E
The drive is designed to be used in applications where the unit may experience
shock and vibrations at greater levels than larger and heavier disk drives will
tolerate.
The design features which allow greater shock tolerance are the use of rugged
heads and media, a dedicated landing zone, closed loop servo positioning and
specially designed motor and actuator assemblies.
Eight side, or four bottom base mounting points are provided to the customer.
The drive is mounted using 6-32 UNC -2B X 0.16 maximum insertion length
screws. Refer to Figure 2-2 in Chapter 2 for the location of the mounting holes.
The system integrator should allow ventilation to the drive to ensure reliable
drive operation over the operating temperature range. The drive may be
mounted in any orientation.
Page 32 Filepro CFP1060E/CFP1060S/CFP1060W
Page 41
SCSI Physical Characteristics Chapter 4
Installing a CFP1060S
The following paragraphs describe the installation procedure for a 8-bit, 50-pin
SCSI-2 interface, model CFP1060S drive.
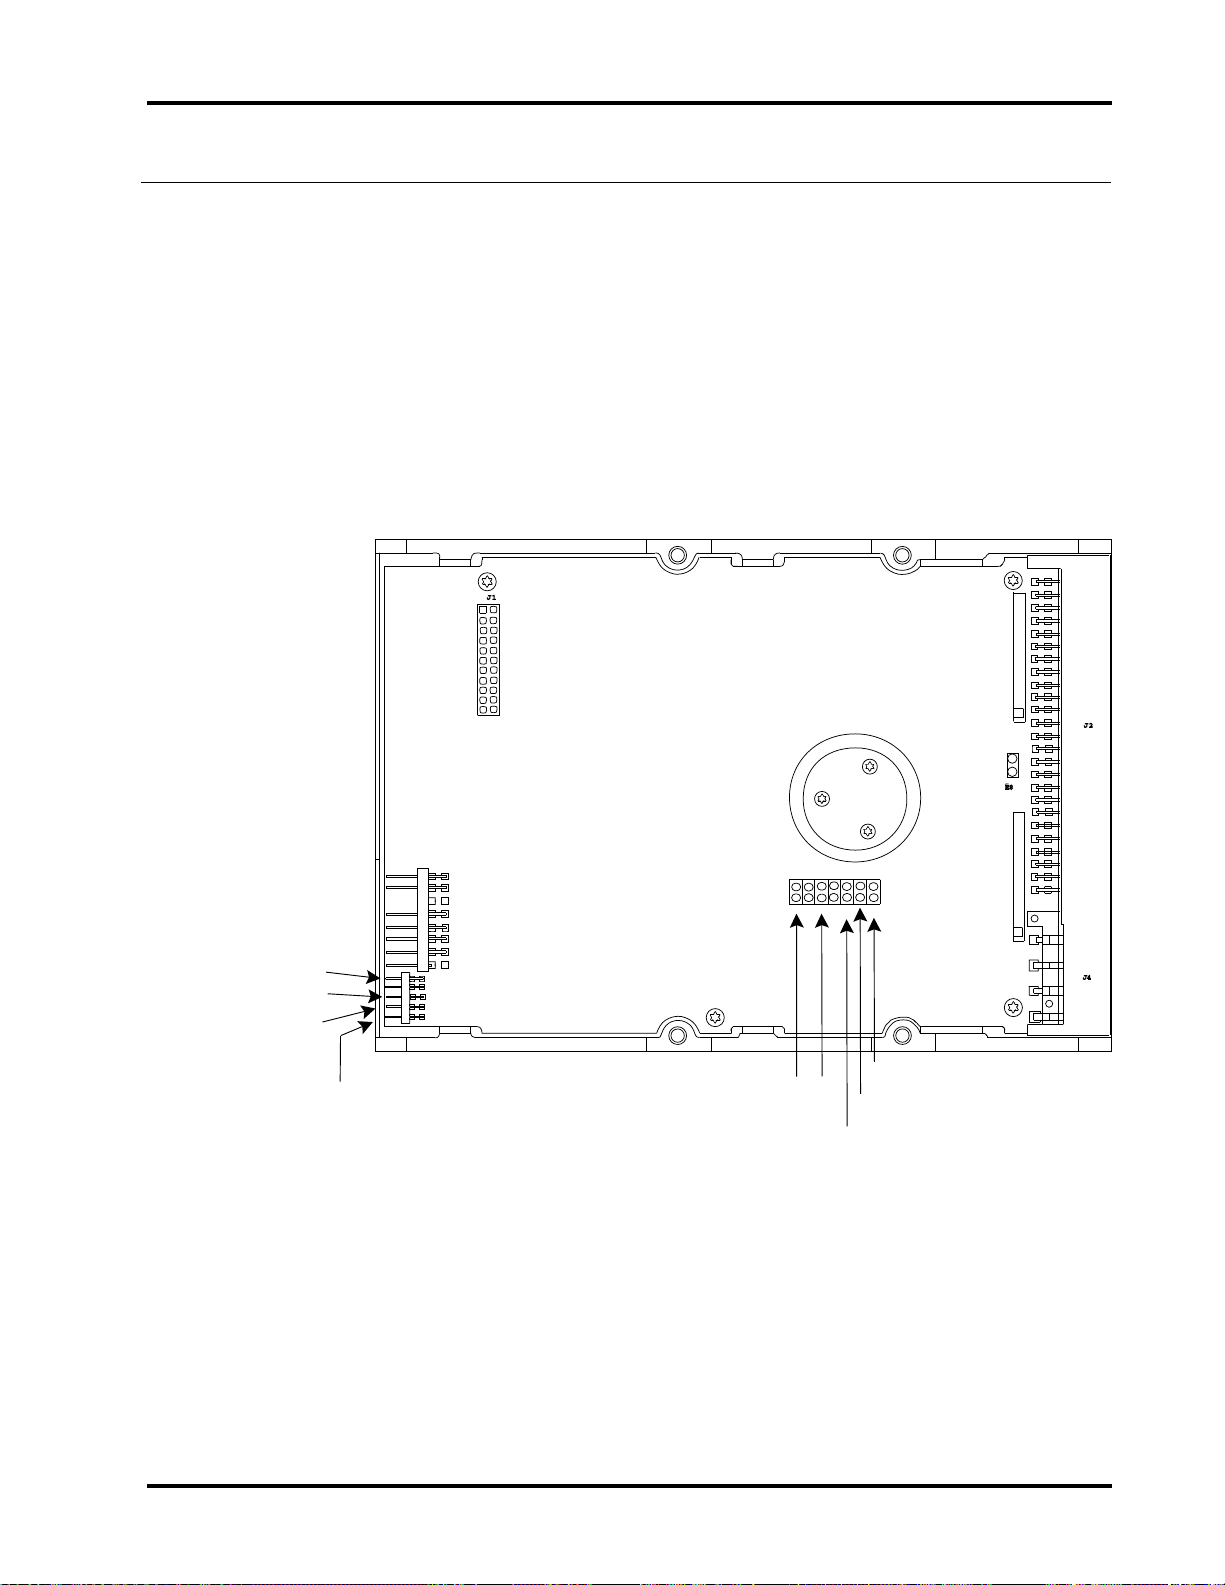
Setting the Drive's Jumpers - CFP1060S
Figure 4-3 shows you where the drive’s jumpers are located.
Figure 4-3
Jumper Locations
J1
OE1
:
OE3
OE5, Disable
Spin
J3
OE6, LED Driver
SS
LED
J6, Header Optional
E1..E3
E4: Reserved
E6 (Delay Spin)
E5 (Disable Spin)
E7 (Disable Parity)
J2
E8
J4
100_4_1
Technical Reference Manual Page 33
Page 42
Chapter 4 SCSI Physical Characteristics
0E2
E2
Out
Out
In
In
Out
Out
In
In
Setting the SCSI Bus Address - CFP1060S
There are three jumpers available for configuration of the SCSI ID: E1, E2, and
E3.
An optional 2mm pin pitch right angle header is located on the front of the
PCBA (opposite the SCSI interface connector) which allows changing the SCSI
IDs while the drive is mounted in the system. The header includes three pins,
0E1, 0E2 and 0E3 which can alternatively be used to select the SCSI Bus
address. This connector may also be used to cable the SCSI ID select to a remote
switch. A receptacle connector Amp P/N 111622-1 or equivalent can be used to
connect a ribbon cable to this header.
Table 4-6 defines the relationship between the jumpers and the SCSI ID:
Table 4-7
Setting the SCSI ID
Optional header 0E1
Standard E1
Out
In
Out
In
Out
In
Out
In
Note: When controlling the SCSI ID remotely, In = Ground or TTL
Low and Out = Open or TTL High.
0E3
E3 SCSI ID
Out 0
Out 1
Out 2
Out 3
In 4
In 5
In 6
In 7
Page 34 Filepro CFP1060E/CFP1060S/CFP1060W
Page 43
SCSI Physical Characteristics Chapter 4
Disabling Spin-Up at Power On - CFP1060S
A jumper in the E5 location, disables spin up after power-on for applications
where spin up sequencing is necessary. An optional 2mm pin pitch right angle
header is located on the front of the PCBA (opposite the SCSI interface
connector) which can alternatively be used to disable spin up. Disabling spin up
on application of power can also be enabled by setting the DSPN bit in MODE
SELECT page 00
(Operating Parameters). The Host must issue a START
H
UNIT command to cause the drive to spin up. Refer to the Ninth Generation
SCSI Technical Reference Manual for additional information regarding the
MODE SELECT and START/STOP UNIT commands. Refer to Figure 4-3 for the
location of the Disable Spin jumper, E5 or 0E5.
Table 4-8
Disabling Spin Up at Power-On
E5 or 0E5 DSPN Result
In 0 Spin Disabled
In 1 Spin Disabled
Out 0 Spin up on Power On
Out 1 Spin Disabled
Note: In = Ground or TTL Low and Out = Open or TTL High.
Delaying Spin Up at Power On - CFP1060S
A jumper in the E6 location, delays spin up on power-up by the value of the
drive's SCSI ID multiplied by 4 seconds (i.e. SCSI ID 4 will delay 16 seconds).
Delaying spin up on application of power can also be enabled by setting the
SDLY bit in MODE SELECT page 00
(Operating Parameters). Refer to the
H
Ninth Generation SCSI Technical Reference Manual for additional information
regarding the MODE SELECT command. Refer to Figure 4-3 for the location of
the Delayed Spin jumper, E6.
Table 4-9
Delaying Spin Up at Power On
E6 SDLY Result
In 0 Spin Delayed
In 1 Spin Delayed
Out 0 Spin up on Power On
Out 1 Spin Delayed
Technical Reference Manual Page 35
Page 44
Chapter 4 SCSI Physical Characteristics
Disabling the SCSI Bus Parity - CFP1060S
SCSI parity is always enabled in both directions, unless the E7 Parity disable
jumper is installed. Installing the jumper will cause the drive to ignore SCSI
bus Parity In but it will continue to generate SCSI bus Parity Out.
Disabling SCSI Bus Terminator Power (TERMPWR) - CFP1060S
Power to the on-board terminators is provided by the higher of the voltage
supplied at Pin #26, J2 or the voltage level at the 5 Volt power input to the drive
minus one diode drop. Termination Power to external terminators can be
supplied by the drive through Pin #26, J2. The signal output characteristics are
described in chapter 5. The TERMPWR line can be disconnected from the drive
by removing Jumper E8.
Table 4-10
Disabling SCSI Bus TERMPWR
Jumper E8 Result
In TERMPWR (J2, Pin #26) connected to the drive's
internal termination power.
Out TERMPWR (J2, Pin #26) open circuit.
Page 36 Filepro CFP1060E/CFP1060S/CFP1060W
Page 45
SCSI Physical Characteristics Chapter 4
Setting the Bus Termination - CFP1060S
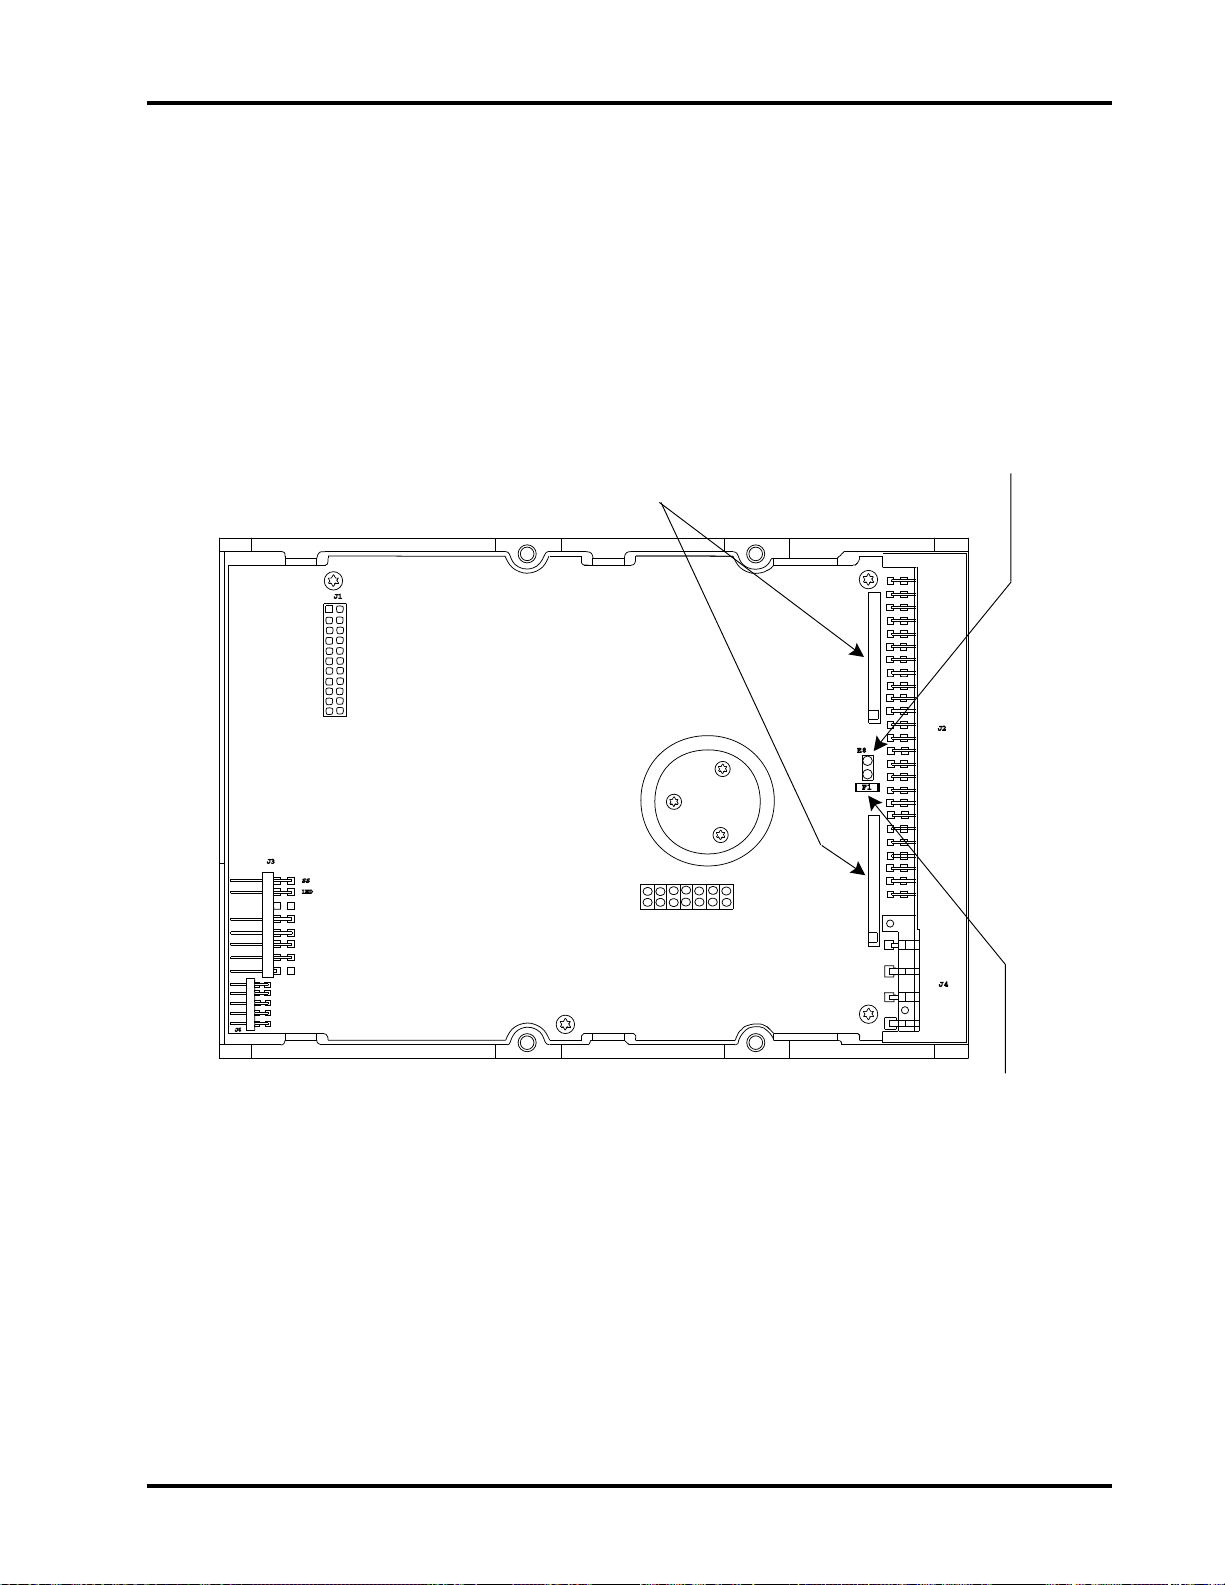
This drive provides on-board Alternative 2 active termination for the SCSI bus.
The termination resistors, which are contained in two Single Inline Packs (SIPs)
should be removed from the drive unless it is a SCSI device at the physical end
of the bus. Figure 4-4 shows the location of the terminator resistors.
Figure 4-4
Terminator Resistor Locations
Remove to
SCSI Terminators.
Remove in all but the last
drive in the chain
J1
Disable TERMPWR
Input/Output
J2
E8
F1
J3
SS
LED
J4
J6
100_4_2
TERMPWR
Fuse
NOTE: The TERMPWR output of the drive is protected by a 1 Ampere fuse. If
external terminators are being powered from the drive and SCSI bus
problems are suspected, verify that the fuse is still operational using a
meter.
Technical Reference Manual Page 37
Page 46
Chapter 4 SCSI Physical Characteristics
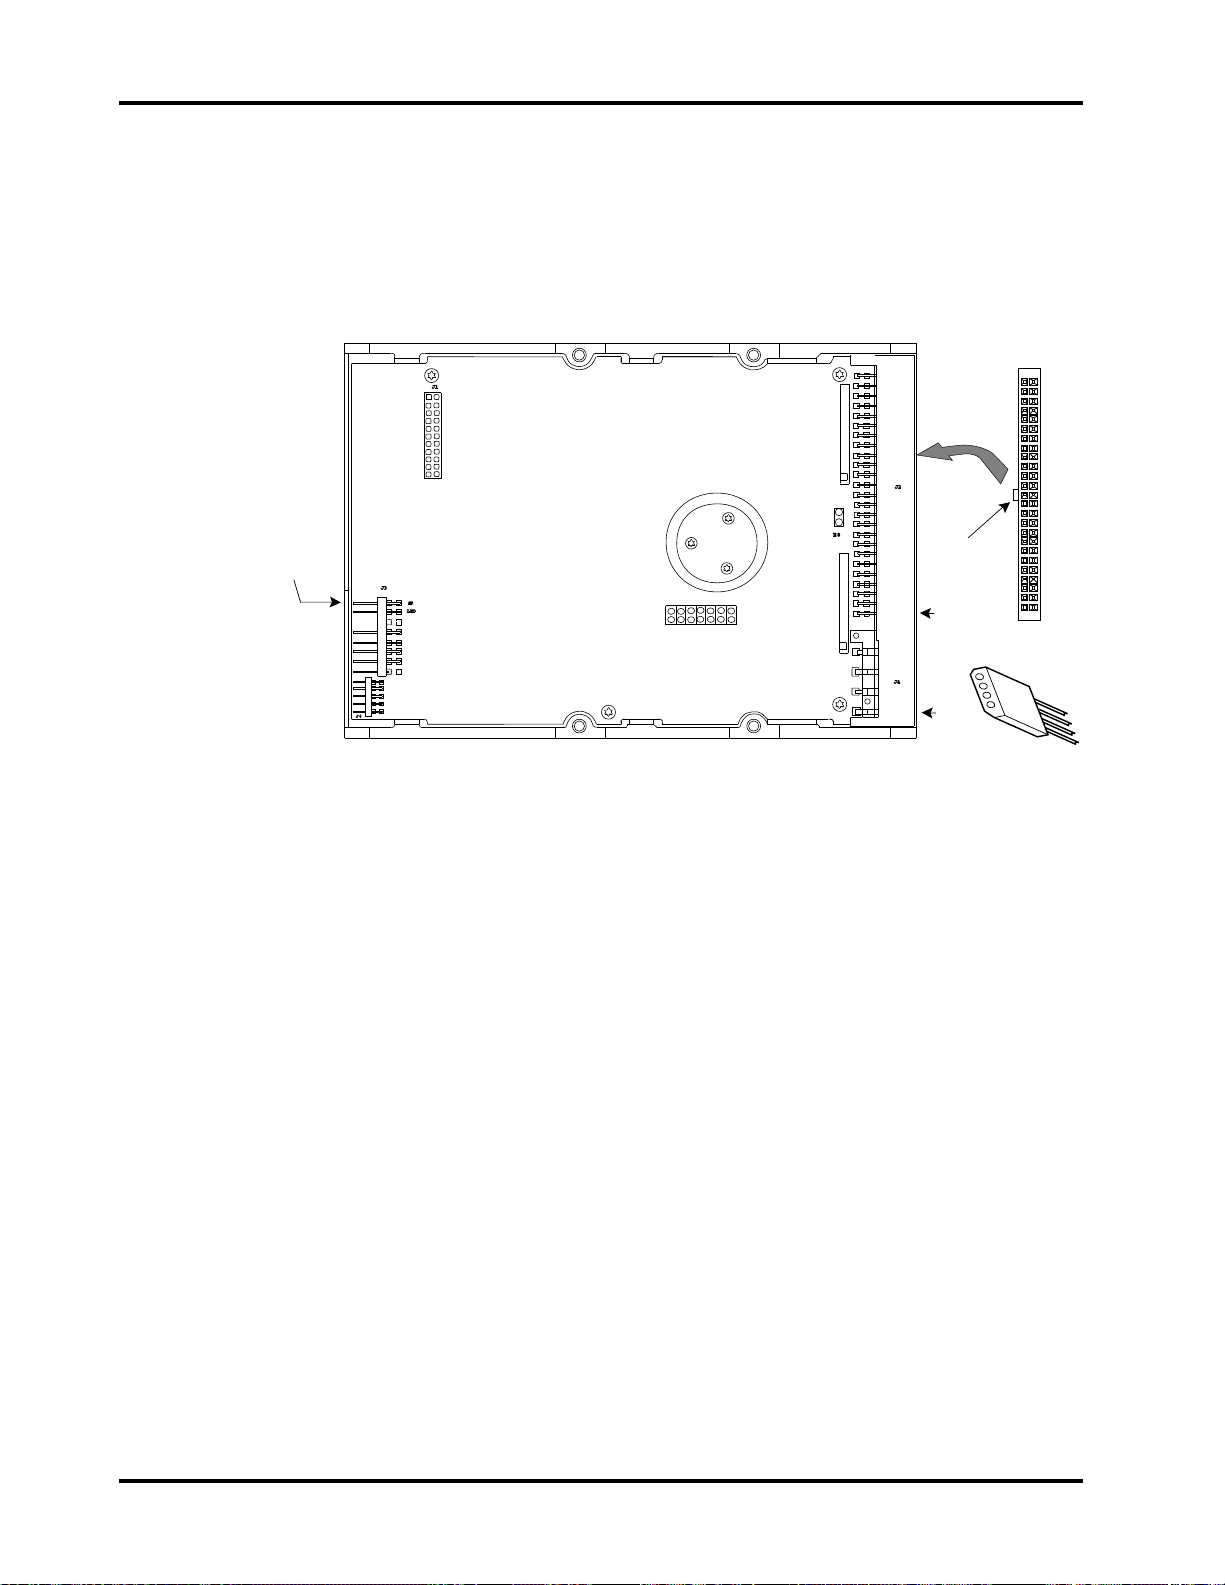
Cabling the Drive - CFP1060S
Connect the SCSI interface cable and the spindle synchronization cable (when
needed) as shown in Figure 4-5.
Figure 4-5
Connecting the cabling
J1
J2
50-pin SCSI
Interface
Spindle
Synchronization
Connection
J3
SS
LED
J6
E8
J4
Key
Pin 1 (typically
indicated by a
colored stripe
on the cable
Pin 1
100_4_3
4-pin Power
Connector
SCSI Bus Cable
The cable and mating connector required to connect the drive to the SCSI bus
are described in Chapter 5. In addition, the cable should meet the following
guidelines, particularly with FAST SCSI-2 systems:
• Do not route the data cable next to the drive PCB or any other high
frequency or large current switching signals. Improper drive operation can
result from improper cable routing.
• Cable stubs should not exceed 0.1 meter (4 inches).
• There should be 0.3 meters (12 inches) of cable between drives.
• The total cable length should not exceed 6 meters (20 feet) and may have to
be reduced if a mixture of round and flat cable are used.
• Do not tightly bundle excess flat cable against each other since this promotes
cross coupling of signals on the cable. Use spacers to maintain a minimum of
0.050 inches (1.27mm) gap between cable runs.
• Do not clamp the cable tightly against a metal chassis since this will degrade
the signal. Use spacers or a non-flammable insulation material to maintain
a gap between the chassis and the cable.
Spindle Synchronization
The spindle rotation of up to 35 drives may be synchronized together by daisy
chaining pin 1 to pin 1 and pin 2 to pin 2 on connector J3. The spindles are
synchronized using a "floating master" concept, where the drives will
synchronize to the first drive to reach full speed. The synchronization tolerance
is 1%.
Page 38 Filepro CFP1060E/CFP1060S/CFP1060W
Page 47
SCSI Physical Characteristics Chapter 4
Attaching Power to the Drive - CFP1060S
The drive has a 4-pin DC power connector, J4 mounted on the PCB. The
recommended mating connector is AMP part number 1-480424-0 utilizing AMP
pins, part number 350078-4 or equivalent.
Connect the DC Power cable to the drive as shown in Figure 4-5.
Mounting the Drive - CFP1060S
The drive is designed to be used in applications where the unit may experience
shock and vibrations at greater levels than larger and heavier disk drives will
tolerate.
The design features which allow greater shock tolerance are the use of rugged
heads and media, a dedicated landing zone, closed loop servo positioning and
specially designed motor and actuator assemblies.
Eight side, or four bottom base mounting points are provided to the customer.
The drive is mounted using 6-32 UNC -2B X 0.16 maximum insertion length
screws. Refer to Figure 2-3 in Chapter 2 for the location of the mounting holes.
The system integrator should allow ventilation to the drive to ensure reliable
drive operation over the operating temperature range. The drive may be
mounted in any orientation.
Technical Reference Manual Page 39
Page 48
Chapter 4 SCSI Physical Characteristics
Installing a CFP1060W
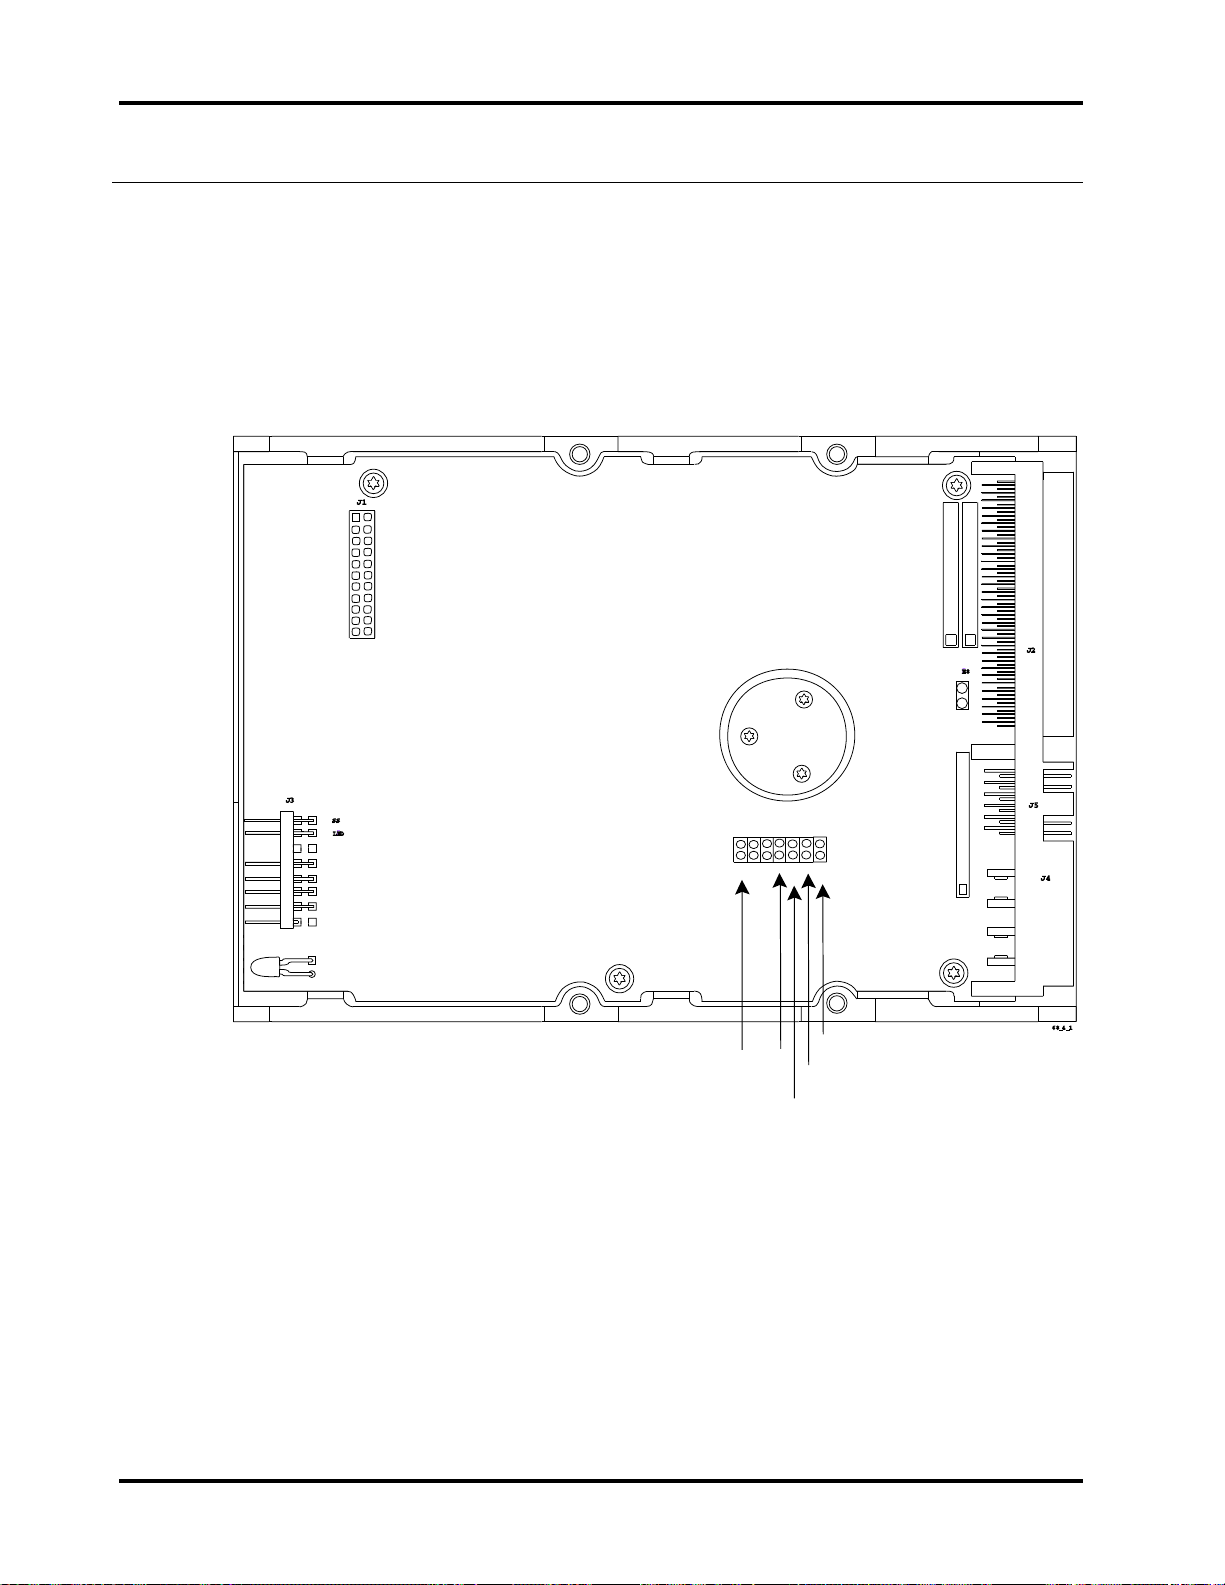
Setting the Drive’s Jumpers - CFP1060W
Figure 4-6 shows you where to access the drive’s jumpers.
Figure 4-6
Jumper Locations
J1
J2
E8
J3
SS
LED
E1. . .E4
E7 (Disable Parity)
J5
J4
68_4_1
E6 (Delay Spin)
E5 (Disable Spin)
Page 40 Filepro CFP1060E/CFP1060S/CFP1060W
Page 49
SCSI Physical Characteristics Chapter 4
Setting the SCSI Bus Address - CFP1060W
There are four jumpers available for configuration of the SCSI ID: E1, E2, E3
and E4.
The 68-pin unified connector includes a standard 2mm pitch auxiliary header
which includes pins to allow remote selection of SCSI IDs. A receptacle
connector Amp P/N 1-111623-7 or equivalent can be used to connect a ribbon
cable to this header.
Table 4-11 defines the relationship between the jumpers or the pins on J5 and
the SCSI ID:
Table 4-11
Setting the SCSI ID
SCSI ID E1 / Pin 1 E2 / Pin 3 E3 / Pin 5 E4 / Pin 7
0
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
Note: Open means open circuit or high impedance. Ground means TTL logic
low or logic ground.
Out/Open Out/Open Out/Open Out/Open
In/Ground Out/Open Out/Open Out/Open
Out/Open In/Ground Out/Open Out/Open
In/Ground In/Ground Out/Open Out/Open
Out/Open Out/Open In/Ground Out/Open
In/Ground Out/Open In/Ground Out/Open
Out/Open In/Ground In/Ground Out/Open
In/Ground In/Ground In/Ground Out/Open
Out/Open Out/Open Out/Open In/Ground
In/Ground Out/Open Out/Open In/Ground
Out/Open In/Ground Out/Open In/Ground
In/Ground In/Ground Out/Open In/Ground
Out/Open Out/Open In/Ground In/Ground
In/Ground Out/Open In/Ground In/Ground
Out/Open In/Ground In/Ground In/Ground
In/Ground In/Ground In/Ground In/Ground
Technical Reference Manual Page 41
Page 50
Chapter 4 SCSI Physical Characteristics
Disabling Spin-Up at Power On - CFP1060W
A jumper in the E5 location, disables spin up on power-on for applications where
spin up sequencing is necessary. Disabling spin up on application of power can
also be enabled by setting the DSPN bit in MODE SELECT page 00
(Operating
H
Parameters). The Host must issue a START UNIT command to cause the drive
to spin up. Refer to the Ninth Generation SCSI Technical Reference Manual for
additional information regarding the MODE SELECT and START/STOP UNIT
commands. Refer to Figure 4-6 for the location of the Disable Spin jumper E5
and the option header.
Table 4-12
Disabling Spin Up at Power On
E5 DSPN Result
In 0 Spin Disabled
In 1 Spin Disabled
Out 0 Spin up on Power On
Out 1 Spin Disabled
Delaying Spin Up at Power On - CFP1060W
A jumper in the E6 location, delays spin up on power-up by the value of the
drive's SCSI ID multiplied by 4 seconds (i.e. SCSI ID 4 will delay 16 seconds).
Delaying spin up on application of power can also be enabled by setting the
SDLY bit in MODE SELECT page 00
(Operating Parameters). Refer to the
H
Ninth Generation SCSI Technical Reference Manual for additional information
regarding the MODE SELECT command. Refer to Figure 4-6 for the location of
the Delayed Spin jumper, E6.
Table 4-13
Delaying Spin Up at Power On
E6 SDLY Result
In 0 Spin Delayed
In 1 Spin Delayed
Out 0 Spin up on Power On
Out 1 Spin Delayed
Disabling the SCSI Bus Parity - CFP1060W
SCSI parity is always enabled in both directions, unless the E7 Parity disable
jumper is installed. Setting the jumper will cause the drive to ignore SCSI bus
parity in but it will continue to generate SCSI bus parity out.
Page 42 Filepro CFP1060E/CFP1060S/CFP1060W
Page 51
SCSI Physical Characteristics Chapter 4
Disabling SCSI Bus Terminator Power (TERMPWR) - CFP1060W
Power to the on-board terminators is provided by the higher of the voltage
supplied at Pins #17, 18, 51 & 52, J2 or the voltage level at the 5 Volt power
input to the drive minus one diode drop. Termination Power to external
terminators can be supplied by the drive through Pins #17, 18, 51 & 52, J2. The
signal output characteristics are described in chapter 5. The TERMPWR line
can be disconnected from the drive by removing Jumper E8.
Table 4-14
Disabling SCSI Bus TERMPWR
Jumper E8 Result
In TERMPWR (J2, Pins #17, 18, 51 & 52) connected
to the drive's internal termination power.
Out TERMPWR (J2, Pins #17, 18, 51 & 52) open
circuit.
Using the J5 Auxiliary Connector
External logic cabled to the J5 connector may be used to control certain
characteristics of the drive or access signals.
Table 5-15
J5 Auxiliary Connector Signal Definitions
Pin Number Signal Name Pin Number Signal Name
1
3
5
7
9
11
- SEL0
Bit 0 of the binary coded SCSI ID selection input. This signal has a value of 0
when it is negated and a value of 1 when it is asserted for the purpose of
selection or arbitration.
This signal is latched within 250 msec of the application of valid power to the
drive or optionally the negation of -RST.
- SEL0
- SEL1
- SEL2
- SEL3
- ENTERM
+5V
2
4
6
8
10
12
- XTFALT
- VUNIQ
- SPSYNC
- XTACTV
- GROUND
- FAULT
If SCSI ID SEL0 is intended to be selected, the host must provide a low
impedance connection from - SEL (0) to - XTFALT or to ground, while the ID is
being latched, through an appropriate means. Refer to chapter 5 for specific
electrical characteristics of these signals.
Technical Reference Manual Page 43
Page 52
Chapter 4 SCSI Physical Characteristics
- XTFAULT
This signal is intended to drive an LED to indicate an external fault condition
has occurred. This signal is held asserted following the application of power or
optionally the negation of -RST during initialization while the SCSI ID is being
read. This signal is not supported but meets the requirement of negating the
signal while the ID is being read.
- SEL1
Bit 1 of the binary coded SCSI ID selection input. This signal has a value of 0
when it is negated and a value of 2 when it is asserted for the purpose of
selection or arbitration.
This signal is latched within 250 msec of the application of valid power to the
drive or optionally the negation of -RST.
If SCSI ID SEL 1 is intended to be selected, the host must provide a low
impedance connection from - SEL1 to - VUNIQ or to ground, while the ID is
being latched, through an appropriate means. Refer to chapter 5 for specific
electrical characteristics of these signals.
- VUNIQ
This signal is an open-collector output available for Vendor Unique usage. This
signal is not supported but meets the requirement of negating the signal while
the ID is being read.
- SEL2
Bit 2 of the binary coded SCSI ID selection input. This signal has a value of 0
when it is negated and a value of 4 when it is asserted for the purpose of
selection or arbitration.
This signal is latched within 250 msec of the application of valid power to the
drive or optionally the negation of -RST.
If SCSI ID SEL2 is intended, to be selected, the host must provide a low
impedance connection from - SEL2 to - SPSYNC or to ground, while the ID is
being latched, through an appropriate means. Refer to chapter 5 for specific
electrical characteristics of these signals.
- SPSYNC
This signal used to provide a spindle rotation synchronization reference. The
pins for all of the drives which are to be synchronized must be connected
together. The drives must be of like model to operate. The spindles are
synchronized using a "floating master" concept, where the drives will
synchronize to the first drive to reach full speed. The synchronization tolerance
is 1%.
This signal meets the requirement of negating the signal while the ID is being
read.
Page 44 Filepro CFP1060E/CFP1060S/CFP1060W
Page 53
SCSI Physical Characteristics Chapter 4
- SEL3
Bit 3 of the binary coded SCSI ID selection input. This signal has a value of 0
when it is negated and a value of 8 when it is asserted for the purpose of
selection or arbitration.
This signal is latched within 250 msec of the application of valid power to the
drive or optionally the negation of -RST.
If SCSI ID SEL3 is intended, to be selected, the host must provide a low
impedance connection from - SEL3 to - XTACTV or to ground, while the ID is
being latched, through an appropriate means. Refer to chapter 5 for specific
electrical characteristics of these signals.
- XTACTV
This signal is an open collector output intended to drive an LED to indicate the
device is active. This signal is negated while the SCSI ID is being read.
- GROUND
This signal is connected to the drive's logic ground.
+5 Volts
This signal provides 5 volts of DC power to drive LEDs and is current limited by
a 120 ohm resistor.
- FAULT
The assertion of this signal will cause the drive to stop any media-altering
activity, which may result in the drive asserting -XTFALT or -VUNIQ, or both.
This signal is intended to be used as a power failure warning and/or as a write
protect input. This signal is not supported by this drive.
Technical Reference Manual Page 45
Page 54
Chapter 4 SCSI Physical Characteristics
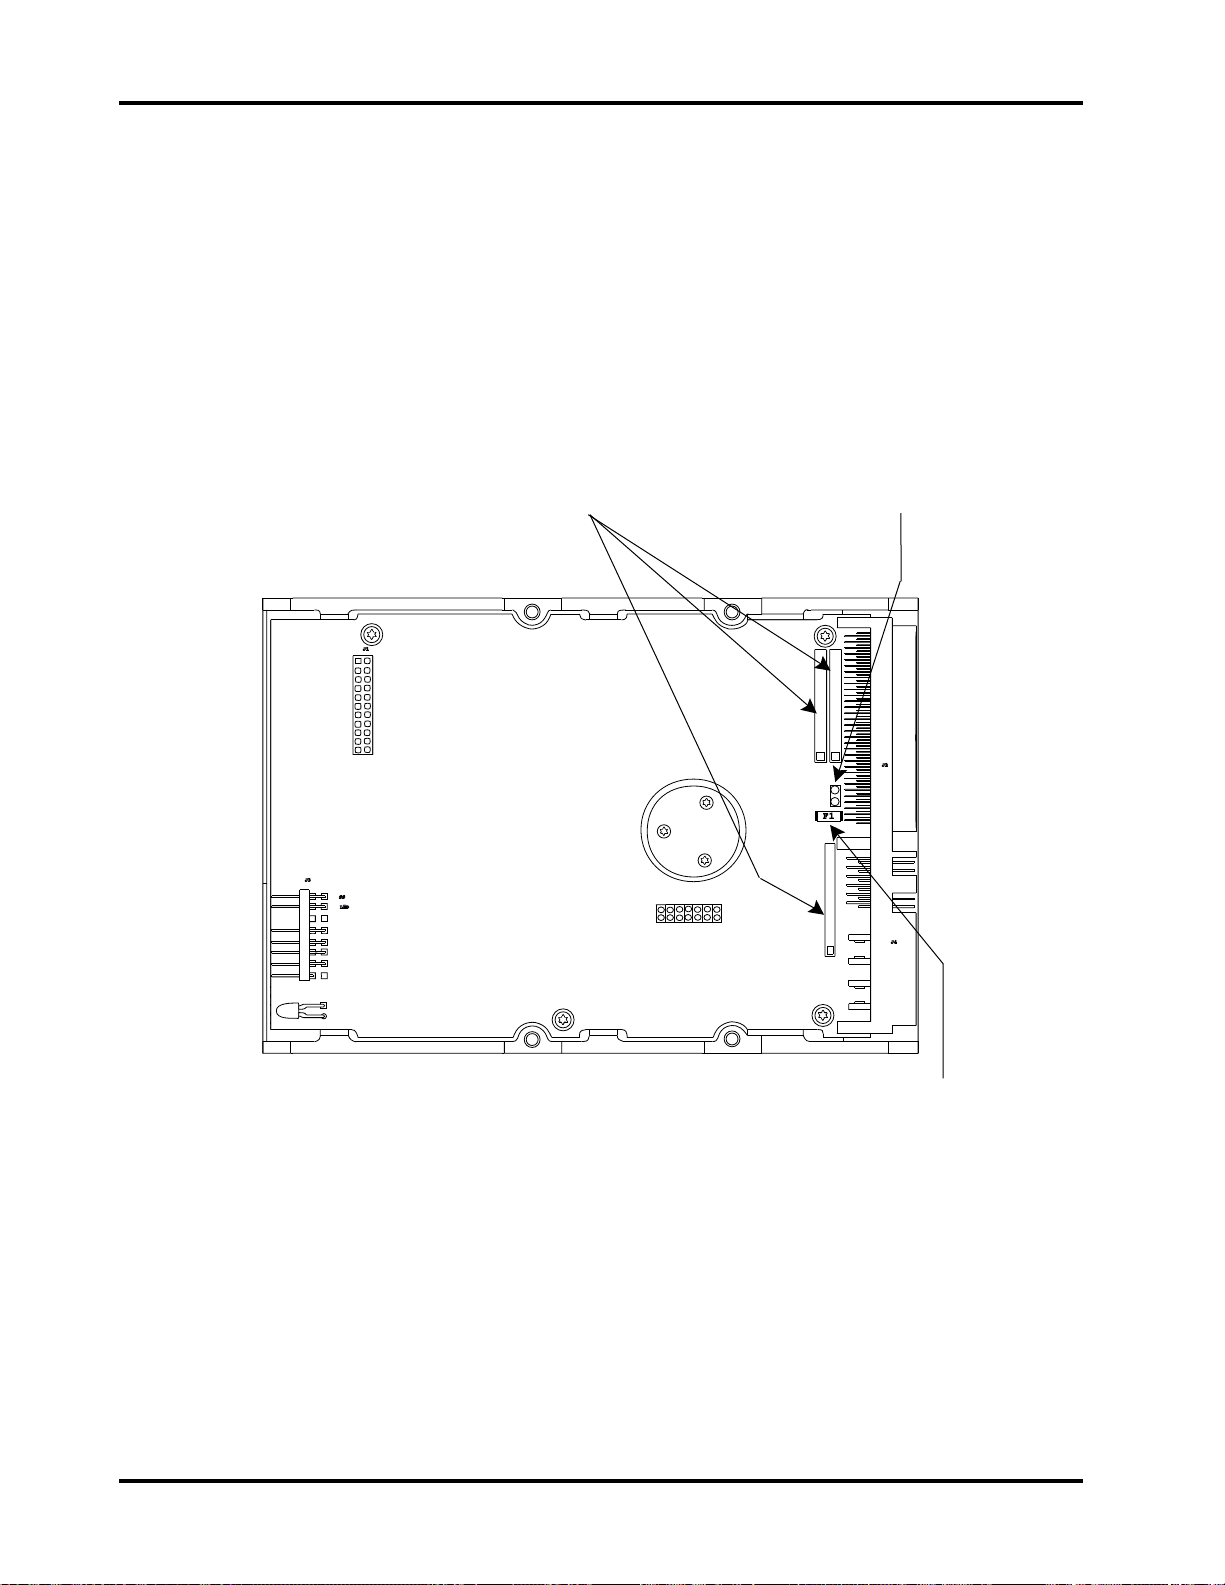
Setting the Bus Termination - CFP1060W
This drive provides on board Alternative 2 active termination for the SCSI bus.
The termination resistors, which are contained in three Single Inline Packs
(SIPs) should be removed from the drive unless it is a SCSI device at the
physical end of the bus. Figure 4-7 shows the location of the terminator
resistors.
Figure 4-7
Terminator Resistor Locations
SCSI Terminators.
Remove in all but the last
drive in the chain
J1
J3
SS
LED
Remove to
Disable TERMPWR
Input/Output
J2
F1
J4
68_4_2
TERMPWR
Fuse
Page 46 Filepro CFP1060E/CFP1060S/CFP1060W
Page 55
SCSI Physical Characteristics Chapter 4
Cabling the Drive - CFP1060W
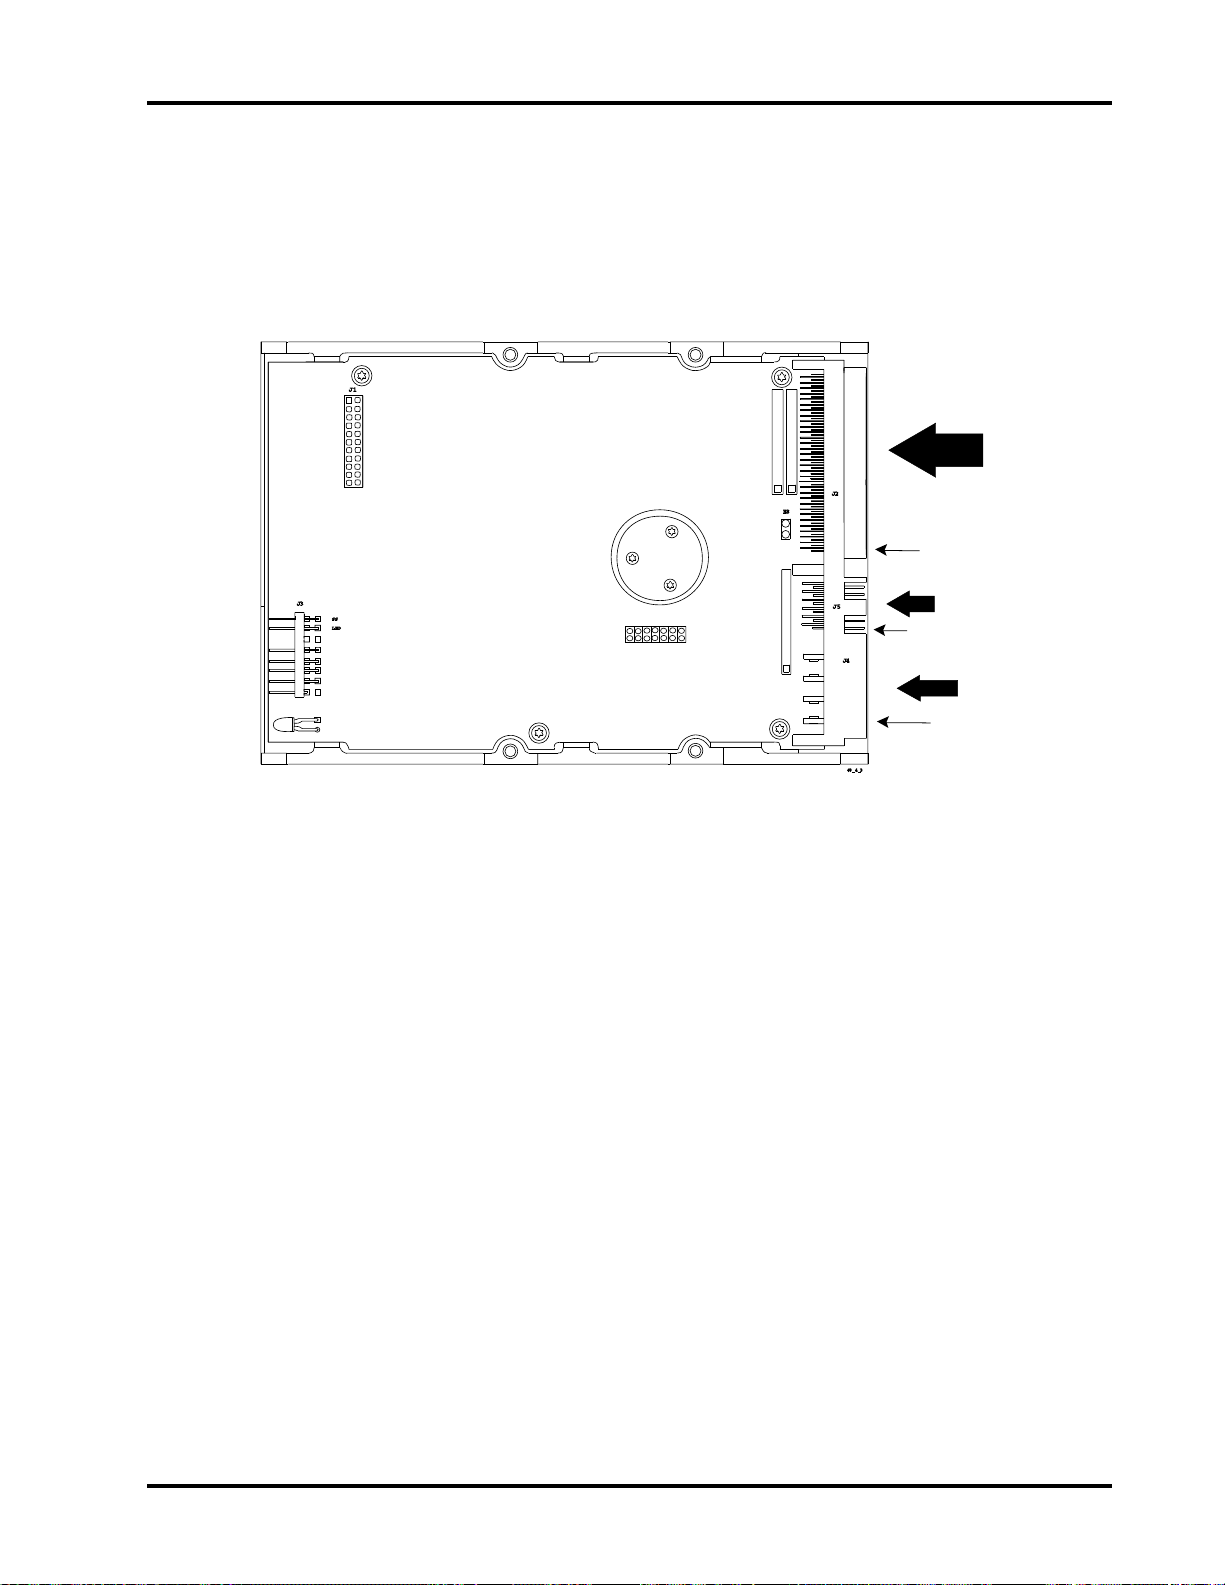
Connect the SCSI interface cable and the spindle synchronization cable (when
needed) as shown in Figure 4-8.
Figure 4-8
Connecting the cabling
J1
68-pin
SCSI
Interface
J2
E8
Pin 1 (typically indicated by a
colored stripe on the cable
Connection
J3
SS
LED
J5
J4
2-mm Auxiliary
Connector
Pin 1
4-pin Power
Connection
Pin 1
68_4_3
SCSI Bus Cable
The cable and mating connector required to connect the drive to the SCSI bus
are described in Chapter 5. In addition, the cable should meet the following
guidelines, particularly with FAST SCSI-2 systems:
• Do not route the data cable next to the drive PCB or any other high
frequency or large current switching signals. Improper drive operation can
result from improper cable routing.
• Cable stubs should not exceed 0.1 meter (4 inches).
• There should be 0.3 meters (12 inches) of cable between drives.
• The total cable length should not exceed 3 meters (10 feet) and may have to
be reduced if a mixture of round and flat cable are used.
• Do not tightly bundle excess flat cable against each other since this promotes
cross coupling of signals on the cable. Use spacers to maintain a minimum of
0.050 inches (1.27mm) gap between cable runs.
• Do not clamp the cable tightly against a metal chassis since this will degrade
the signal. Use spacers or a non-flammable insulation material to maintain
a gap between the chassis and the cable.
Technical Reference Manual Page 47
Page 56
Chapter 4 SCSI Physical Characteristics
Mixing Wide and Narrow SCSI Devices on a SCSI Bus
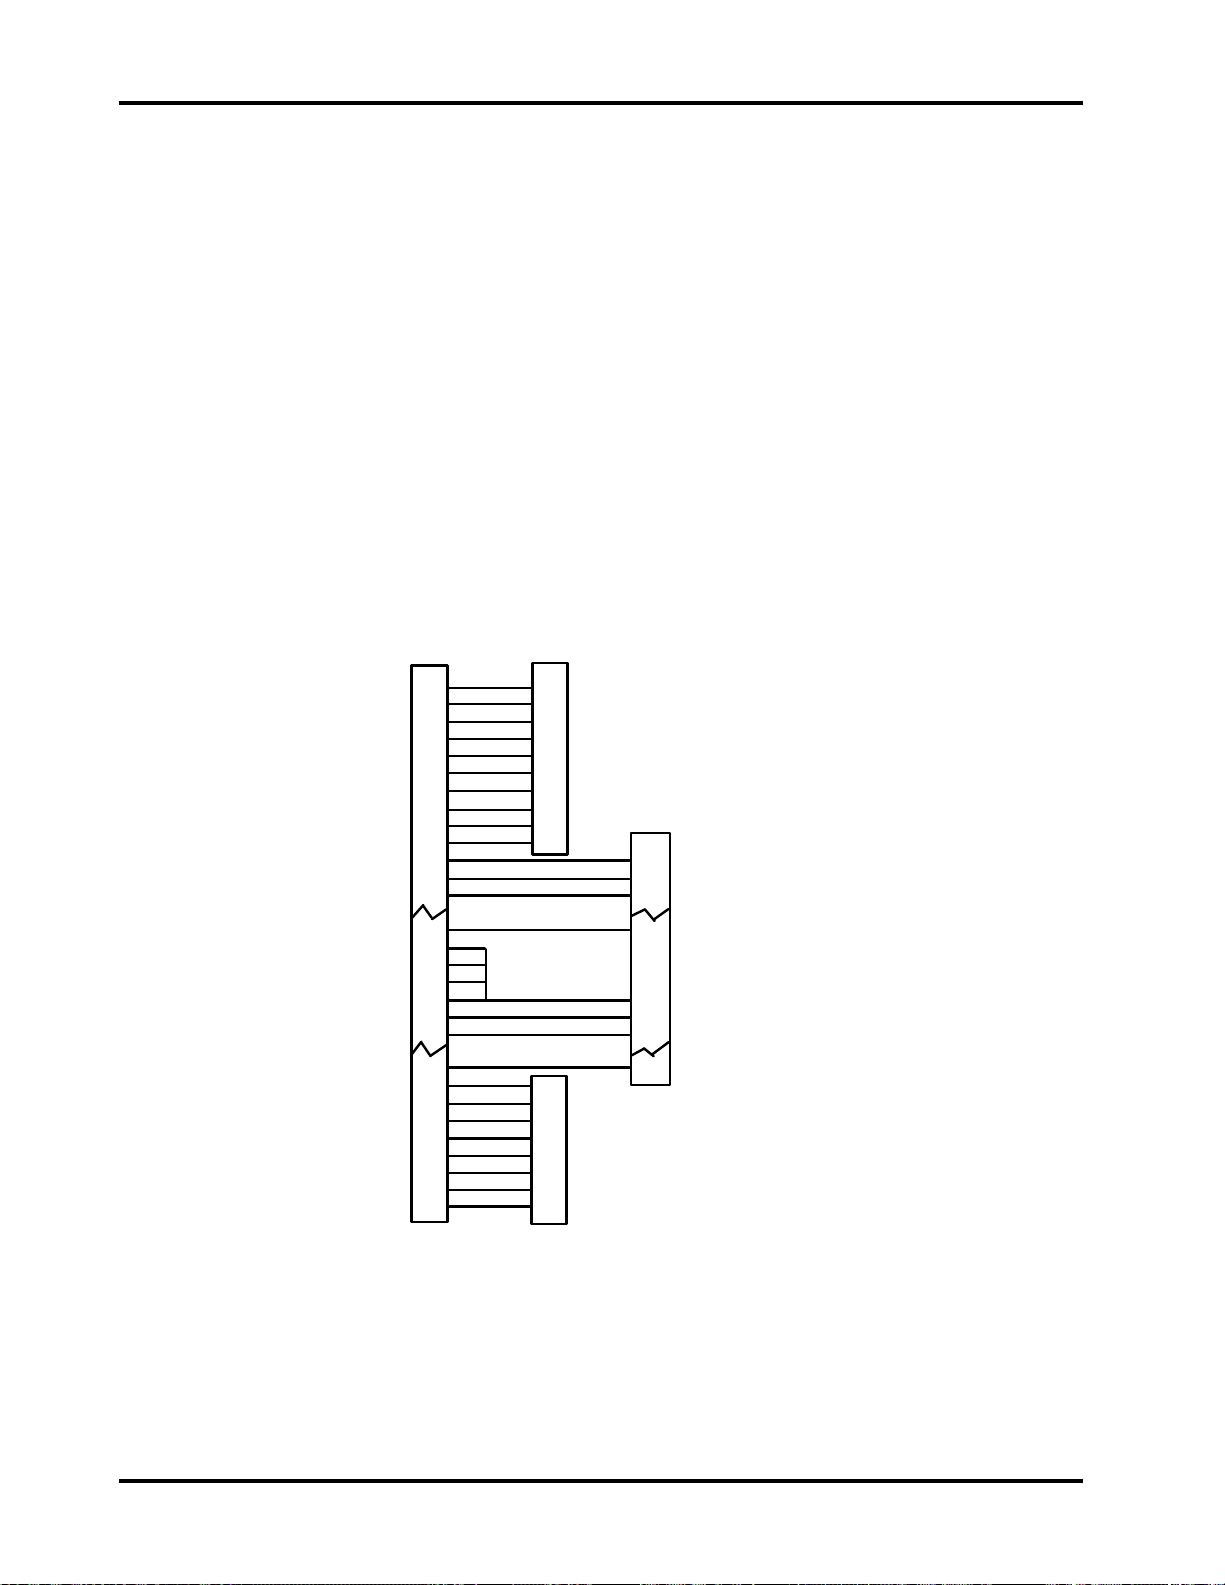
It may sometimes be desirable to attach Narrow SCSI devices such as tape
backup devices or CDROMs to the same SCSI Host Bus Adapter being used to
control Wide SCSI devices, such as the CFP1060W. Intermixing of both Wide
and Narrow SCSI devices on the same bus required special considerations:
• The Narrow SCSI devices must be placed at the physical end of the bus
• The high byte of the SCSI data bus must be terminated at the transition
adapter from the 34-pair wire to the 25-pair wire. Figure 4-9 shows the
interconnection.
• The cable impedance of the 34-pair wire and the 25-pair wire should be as
closely matched as possible.
• The 68-pair cable with 30 AWG wire uses four wires to carry TERMPWR,
which must be joined to wire 26 of the 25-pair wire, if terminator power has
to be carried over the cable.
Figure 4-9
Wide-to-Narrow Adapter
P Cable
Ground 1
-DB (12)
Ground
-DB (13)
Ground 5
-DB (14)
Ground 7
-DB (15)
Ground 9
-DB(P1) 10
Ground 11
-DB (0)
Ground 13
Ground 32
TERMPWR
TERMPWR
TERMPWR
TERMPWR
Reserved
Reserved
-I/O 60
Ground 61
-DB(8) 62
Ground 63
-DB(9) 64
Ground 65
-DB(10) 66
Ground 67
-DB(11) 68
2
3
4
6
8
12
33
34
35
36
37
38
T
E
R
M
I
N
A
T
O
R
T
E
R
M
I
N
A
T
O
R
A Cable
1 Ground
2
3 Ground
22 Ground
23
24
25 Open
26
27
28
50 -I/O
-DB (0)
Reserved
Reserved
TERMPWR
Reserved
Reserved
Spindle Synchronization
The spindle rotation of up to 35 drives may be synchronized together by daisy
chaining pin 1 to pin 1 and pin 2 to pin 2 of each drive on connector J3 or
chaining pin 6 of the 2mm option header J5. The spindles are synchronized
using a "floating master" concept, where the drives will synchronize to the first
drive to reach full speed. The synchronization tolerance is 1%.
Page 48 Filepro CFP1060E/CFP1060S/CFP1060W
Page 57
SCSI Physical Characteristics Chapter 4
Attaching Power to the Drive - CFP1060W
The drive has a 4-pin DC power connector, J4, which is part of the Unified
Connector, mounted on the PCB. The recommended mating connector is AMP
part number 1-480424-0 utilizing AMP pins, part number 350078-4 or
equivalent.
Mounting the Drive - CFP1060W
The drive is designed to be used in applications where the unit may experience
shock and vibrations at greater levels than larger and heavier disk drives will
tolerate.
The design features which allow greater shock tolerance are the use of rugged
heads and media, a dedicated landing zone, closed loop servo positioning and
specially designed motor and actuator assemblies.
Eight side, or four bottom base mounting points are provided to the customer.
The drive is mounted using 6-32 UNC -2B X 0.16 maximum insertion length
screws. Refer to Figure 2-4 in Chapter 2 for the location of the mounting holes.
The system integrator should allow ventilation to the drive to ensure reliable
drive operation over the operating temperature range. The drive may be
mounted in any orientation.
Technical Reference Manual Page 49
Page 58
Chapter 4 SCSI Physical Characteristics
Page 50 Filepro CFP1060E/CFP1060S/CFP1060W
Page 59
Interface Physical Characteristics
5
Electrical Description
The paragraphs which follow describe the input and output electrical characteristics
of the drive.
Output Characteristics
The output drivers for Data, Parity, REQ and ACK are optionally active
negation. When they are set for active negation, they have three states:
asserted, negated and high impedance. The remainder of the signals have open
collector (drain) outputs. The drivers maintain a high impedance state during
power-on and power-off cycles. The driven signals have the following output
characteristics when measured at the drive connector:
Table 5-1
Active Negation Driver Output Signal Characteristics
Signal Characteristic Value
Signal Assertion 0.1 VDC to 0.5 VDC at 48 mA
Minimum Driver Output Capability 48 mA (sinking) at 0.5 VDC
Signal Negation 2.0 VDC to 3.24 VDC at 7 mA
3.0 VDC at 20 mA
Table 5-2
Open Collector Driver Output Signal Characteristics
Signal Characteristic Value
Signal Assertion 0.0 VDC to 0.5 VDC at 48 mA
Minimum Driver Output Capability 48 mA (sinking) at 0.5 VDC
Signal Negation 2.5 VDC to 5.25 VDC
Technical Reference Manual Page 51
Page 60
Chapter 5 SCSI Physical Characteristics
Input Characteristics
The characteristics of the input receivers and the requirements for each signal
received by the drive as measured at the drive connector are shown in table 5-3:
Table 5-3
Drive Input Signal Characteristics
Signal Characteristic Value
Signal Assertion 0.0 VDC to 0.8 VDC
Signal Negation 2.0 VDC to 5.25 VDC
Input Load (low level)
Input Load (high level)
-20 µA to 0.0 mA at 0.5 VDC
0.0 mA to 20 µA at 2.7 VDC
Model-Specific SCSI Physical Characteristics
The sections which follow describe, for each of the drive models, those SCSI
characteristics which vary from model to model. These characteristics include:
• Termination
• Cable requirements
• Connector requirements
• Connector Pin assignments
• Interface Timing requirements
Page 52 Filepro CFP1060E/CFP1060S/CFP1060W
Page 61
SCSI Physical Characteristics Chapter 5
CFP1060E (WIDE, 80-pin Single Connector Attachment [SCA])
External Terminator Power
The interface connector carries both power and ground so a separate TERMPWR
interface line is not provided.
Internal Termination
This version of the drive has no on-board termination so the drive must be
externally terminated. Alternative 2 active termination is recommended.
Alternative 1 passive termination is not suitable for this application.
Cable Requirements
This version of the drive is designed to interface directly to a mating connector
which is on a passive back plane or directly into a motherboard. The same
guidelines relative to impedance, stub length and distance between stubs apply
for SCSI bus signal reliability. These guidelines may not be directly translated
to a back plane design so these design rules are to be viewed with respect to the
intended purpose of controlling reflections and the propagation of signals down
the bus. Since the characteristics for PCB signal traces are affected by trace
width, proximity to ground, and trace routing, careful review of the back plane
design and analysis of signal quality is highly recommended.
Connector Requirements
The drive's connector will mate with a AMP Champ 2-557103-1 vertical
receptacle or the AMP Champ 2-557101-1 right angle receptacle.
Single Connector Attachment (SCA) Signal Definitions
Power
Four +12 Volt signals provide the +12 volt power to the drive. The current
return for the +12 volt power is through the +12 Volt Ground signals. The
maximum current that can be provided to the drive through the +12 Volt signal
pins is 3 Amperes. The supply current and return current must be distributed
as evenly as possible among the pins. The maximum current is while the drive
motor is starting.
Three +5 Volt signal pins provide +5 volt power to the drive. The current return
for the +5 volt power is through the +5 Volt Ground pins. It is expected that the
+5 Volt Ground will also establish the digital logic ground for the drive. The
maximum current that can be provided to the drive through the +5 Volt signal
pins is 2 Amperes. The supply current and return current must be distributed
as evenly as possible among the pins.
These specifications refer to the connector's characteristics. Refer to Chapter 2
for the drive's power requirements.
Technical Reference Manual Page 53
Page 62
Chapter 5 SCSI Physical Characteristics
Spindle Sync
The spindle rotation of up to 35 drives may be synchronized together by daisy
chaining pin 1 to pin 1 and pin 2 to pin 2 of each drive on connector J3. The
spindles are synchronized using a "floating master" concept, where the drives
will synchronize to the first drive to reach full speed. The synchronization
tolerance is 1%.
Table 5-4
Electrical Characteristics for the Spindle Sync Signal
STATE Current Voltage
High
0 < I
< 20 µA
IH
2.5 V < V
< VCC + 0.3 V
IH
Low
0 < I
< -48 mA -0.1 V < VIL < 0.4 V
OH
LED Out
The LED out signal is driven by the drive when the drive is performing a SCSI
operation. The LED out signal is designed to pull down the cathode of an LED.
The anode is attached to the proper +5 volt supply through an appropriate
current limiting resistor. The LED and the current limiting resistor are external
to the drive.
Table 5-5
Output Characteristics of the LED Driver Signal
State Current Drive Available Output Voltage
Drive LED Off
Drive LED On
0 < I
I
< 100 µA
OH
< -30 mA 0 < VOL < 0.8 Volts
OL
Motor Start Controls
Table 5-6
Electrical Characteristics for RMT_START and DLYD_START
State Current Voltage
Open
Ground
0 < I
0 < I
< +100 µA
IH
< -3 mA -0.5 V < VIL < 0.4 V
OH
2.4 V < VIH < VCC + 0.5 V
SCSI ID Selection
Table 5-7
Electrical Characteristics for the SCSI ID Signals SCSI ID (0) - (3)
State Current Voltage
Open
Ground
0 < I
0 < I
< +100 µA
IH
< -3 mA -0.5 V < VIL < 0.4 V
OH
2.4 V < VIH < VCC + 0.5 V
Page 54 Filepro CFP1060E/CFP1060S/CFP1060W
Page 63
SCSI Physical Characteristics Chapter 5
Interface Pin Assignments
The pin assignments for the interface connector are shown below:
Table 5-8
Interface Signal Definitions
Pin Signal Pin Signal
1 +12 Volt 41 +12 Volt Ground
2 +12 Volt 42 +12 Volt Ground
3 +12 Volt 43 +12 Volt Ground
4 +12 Volt 44 +12 Volt Ground
5 Reserved / NC 45 Reserved / NC
6 Reserved / NC 46 Reserved / NC
7 -DB(11) 47 Ground
8 -DB(10) 48 Ground
9 -DB(9) 49 Ground
10 -DB(8) 50 Ground
11 -I/O 51 Ground
12 -REQ 52 Ground
13 -C/D 53 Ground
14 -SEL 54 Ground
15 -MSG 55 Ground
16 -RST 56 Ground
17 -ACK 57 Ground
18 -BSY 58 Ground
19 -ATN 59 Ground
20 -DB(P0) 60 Ground
21 -DB(7) 61 Ground
22 -DB(6) 62 Ground
23 -DB(5) 63 Ground
24 -DB(4) 64 Ground
25 -DB(3) 65 Ground
26 -DB(2) 66 Ground
27 -DB(1) 67 Ground
28 -DB(0) 68 Ground
29 -DB(P1) 69 Ground
30 -DB(15) 70 Ground
31 -DB(14) 71 Ground
32 -DB(13) 72 Ground
33 -DB(12) 73 Ground
34 +5 Volt 74 +5 Volt Ground
35 +5 Volt 75 +5 Volt Ground
36 +5 Volt 76 +5 Volt Ground
37 SYNC 77 LED
38 RMT_START 78 DLYD_START
39 SCSI ID (0) 79 SCSI ID (1)
40 SCSI ID (2) 80 SCSI ID (3)
Notes:
1. The minus sign (-) indicates active low.
2. Pins marked Reserved are not connected.
Technical Reference Manual Page 55
Page 64
Chapter 5 SCSI Physical Characteristics
Interface Timing Requirements
Unless otherwise noted, the delay-time measurements are calculated from signal
conditions existing at the drive's own SCSI bus connector. Normally these
measurements (except cable skew delay) can be made without considering delays
in the inter-connect system.
Table 5-9
SCSI Bus Timing Values
Timing Value *
Timing Description fast slow asynch
Arbitration Delay
Bus Clear Delay
Bus Free Delay
Bus Set Delay
Bus Settle Delay
Cable Skew Delay
1
Data Release Delay
Receive Assertion Period
Receive Hold Time
Receive Negation Period
Receive Setup Time
Reset Hold Time
Selection Abort Time
Selection Time-out Delay
System Deskew Delay
Transmit Assertion Period
Transmit Hold Time
Transmit Negation Period
Transmit Setup Time
2.4
µs
800 ns 800 ns 800 ns
800 ns 800 ns 800 ns
1.8
µs
400 ns 400 ns 400 ns
4ns 4ns 4ns
400 ns 400 ns 400 ns
22 ns 70 ns n/a
25 ns 25 ns n/a
22 ns 70 ns n/a
15 ns 15 ns n/a
25
µs
200
µs
2
250 ms 250 ms 250 ms
20 ns 45 ns 45 ns
30 ns 80 ns n/a
33 ns 53 ns n/a
30 ns 80 ns n/a
23 ns 23 ns n/a
2.4
1.8
25
200
µs
µs
µs
µs
2.4
1.8
25
200
µs
µs
µs
µs
Notes:
1
This time does not apply at the SCSI connector of the drive.
2
This is a recommended time. It is not mandatory.
Page 56 Filepro CFP1060E/CFP1060S/CFP1060W
Page 65
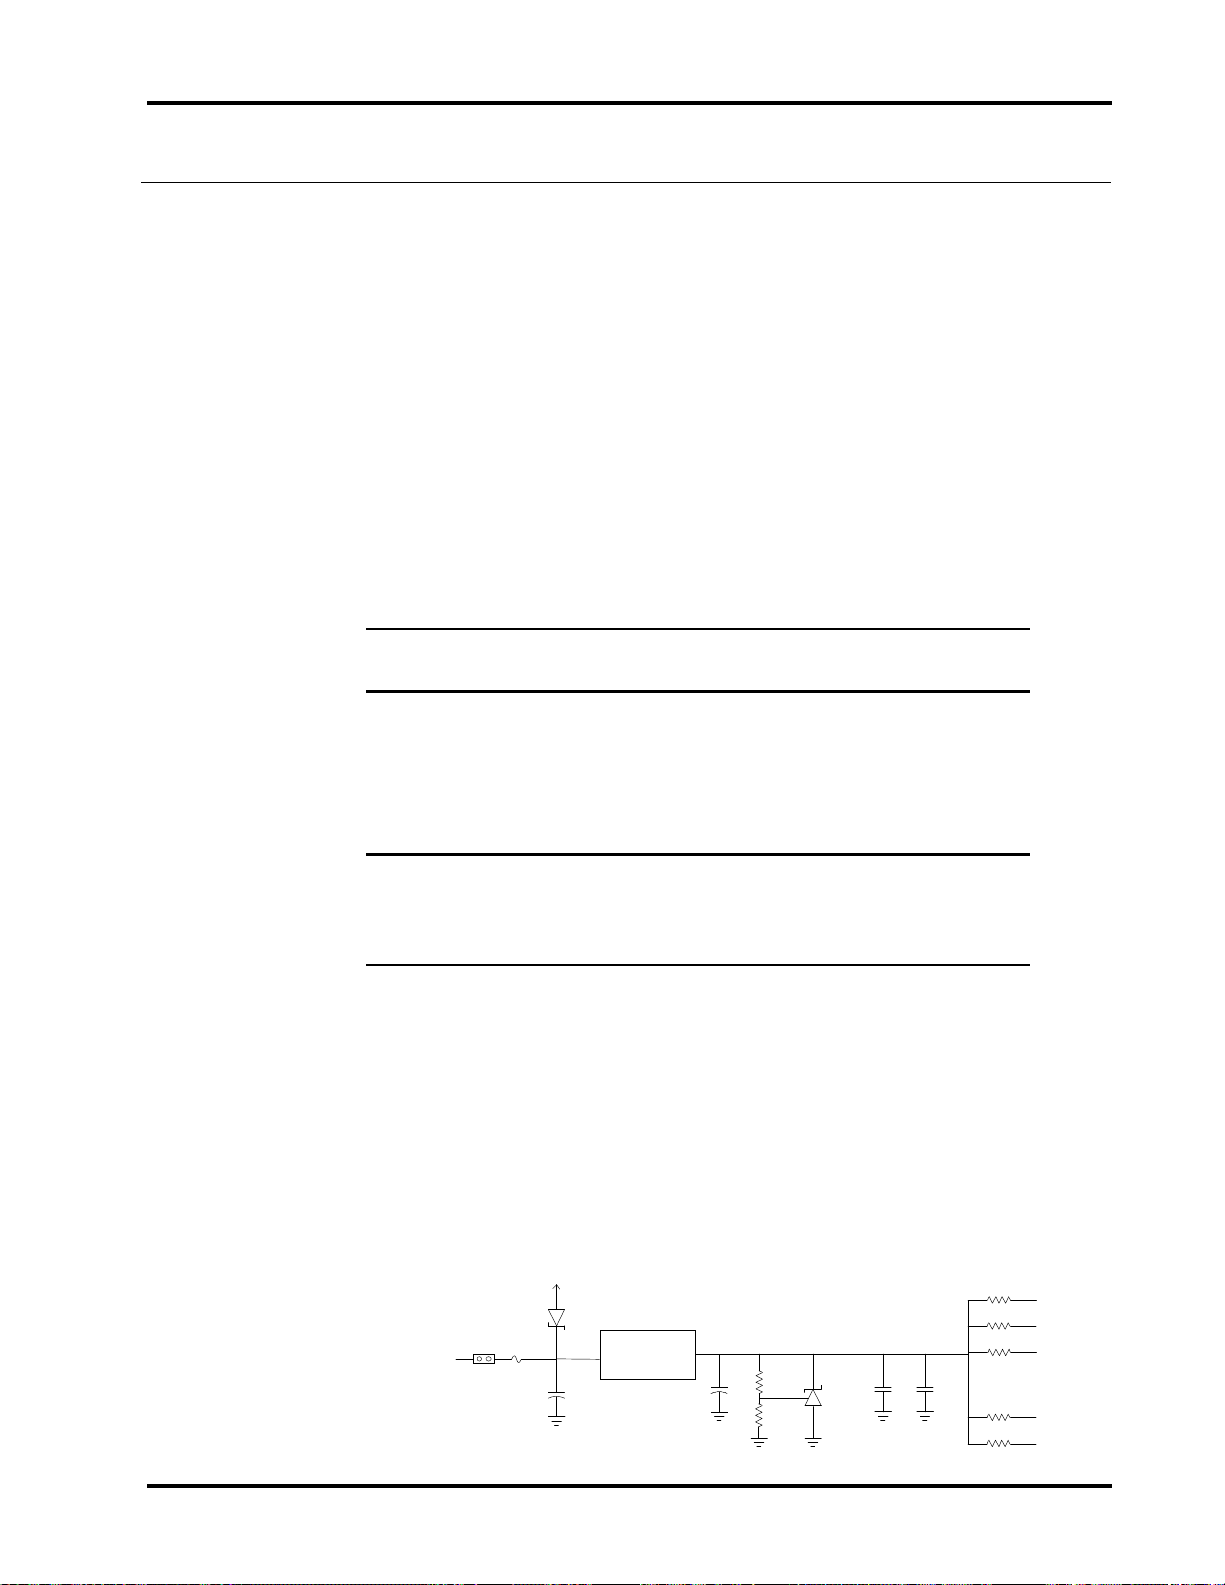
SCSI Physical Characteristics Chapter 5
Model CFP1060S (Narrow, 50-pin SCSI)
External Terminator Power
Power to the on-board terminators is provided by the higher of the voltage
supplied at Pin #26, J2 or the voltage level at the 5 Volt power input to the drive
minus one diode drop. The diode prevents back flow of current to the drive.
Termination Power to external terminators can be supplied by the drive through
Pin #26, J2. The TERMPWR line can be disconnected from the drive by
removing Jumper E8. Table 5-10 describes the electrical characteristics of the
TERMPWR line when it is used to supply power to an external terminator.
Table 5-11 describes the required electrical characteristics for any external
source of termination power.
Table 5-10
TERMPWR Output Electrical Characteristics
Signal Characteristic Value
Supply voltage 4.06 VDC to 4.56 VDC
Minimum source capability: 800 mA (fused at 1000 mA)
Table 5-11
TERMPWR Input Electrical Characteristics
Signal Characteristic Value
Input voltage 4.00 VDC to 5.25 VDC
Minimum source capability: 1000 mA (fused at 1000 mA)
Sink current: 1.0 mA maximum, excluding
Internal Termination
This drive provides on-board Alternative 2 active termination for the SCSI bus.
The termination resistors, which are contained in two Single Inline Packs (SIPs)
should be removed from the drive unless it is a SCSI device at a physical end of
the bus. The terminator equivalent circuit is shown below for reference:
Figure 5-1
Terminator Equivalent Circuit
TERMPWR
E8
F1
+5V
Voltage
Regulator
power to the internal terminator.
2.5K
10K
110
: :
: :
: :
-DB0
-DB1
-DB2
-REQ
-I/O
Technical Reference Manual Page 57
Page 66
Chapter 5 SCSI Physical Characteristics
Cable Requirements
A 50 conductor cable no more than 6 meters (19.68 feet) cumulative length with
at least 28 AWG wire size and a characteristic impedance of 70 to 100 ohms (84
ohms nominal) is required. In systems which use the fast synchronous transfer
option, the cable should meet the following additional requirements:
Table 5-12
Interface Cable Electrical Characteristics
Specification Value
Signal Attenuation 0.095dB maximum per meter at 5 Mhz
Pair-to-Pair Propagation Delay Delta 0.20 ns maximum per meter
DC Resistance 0.230 ohms maximum per meter at 20° C
Page 58 Filepro CFP1060E/CFP1060S/CFP1060W
Page 67
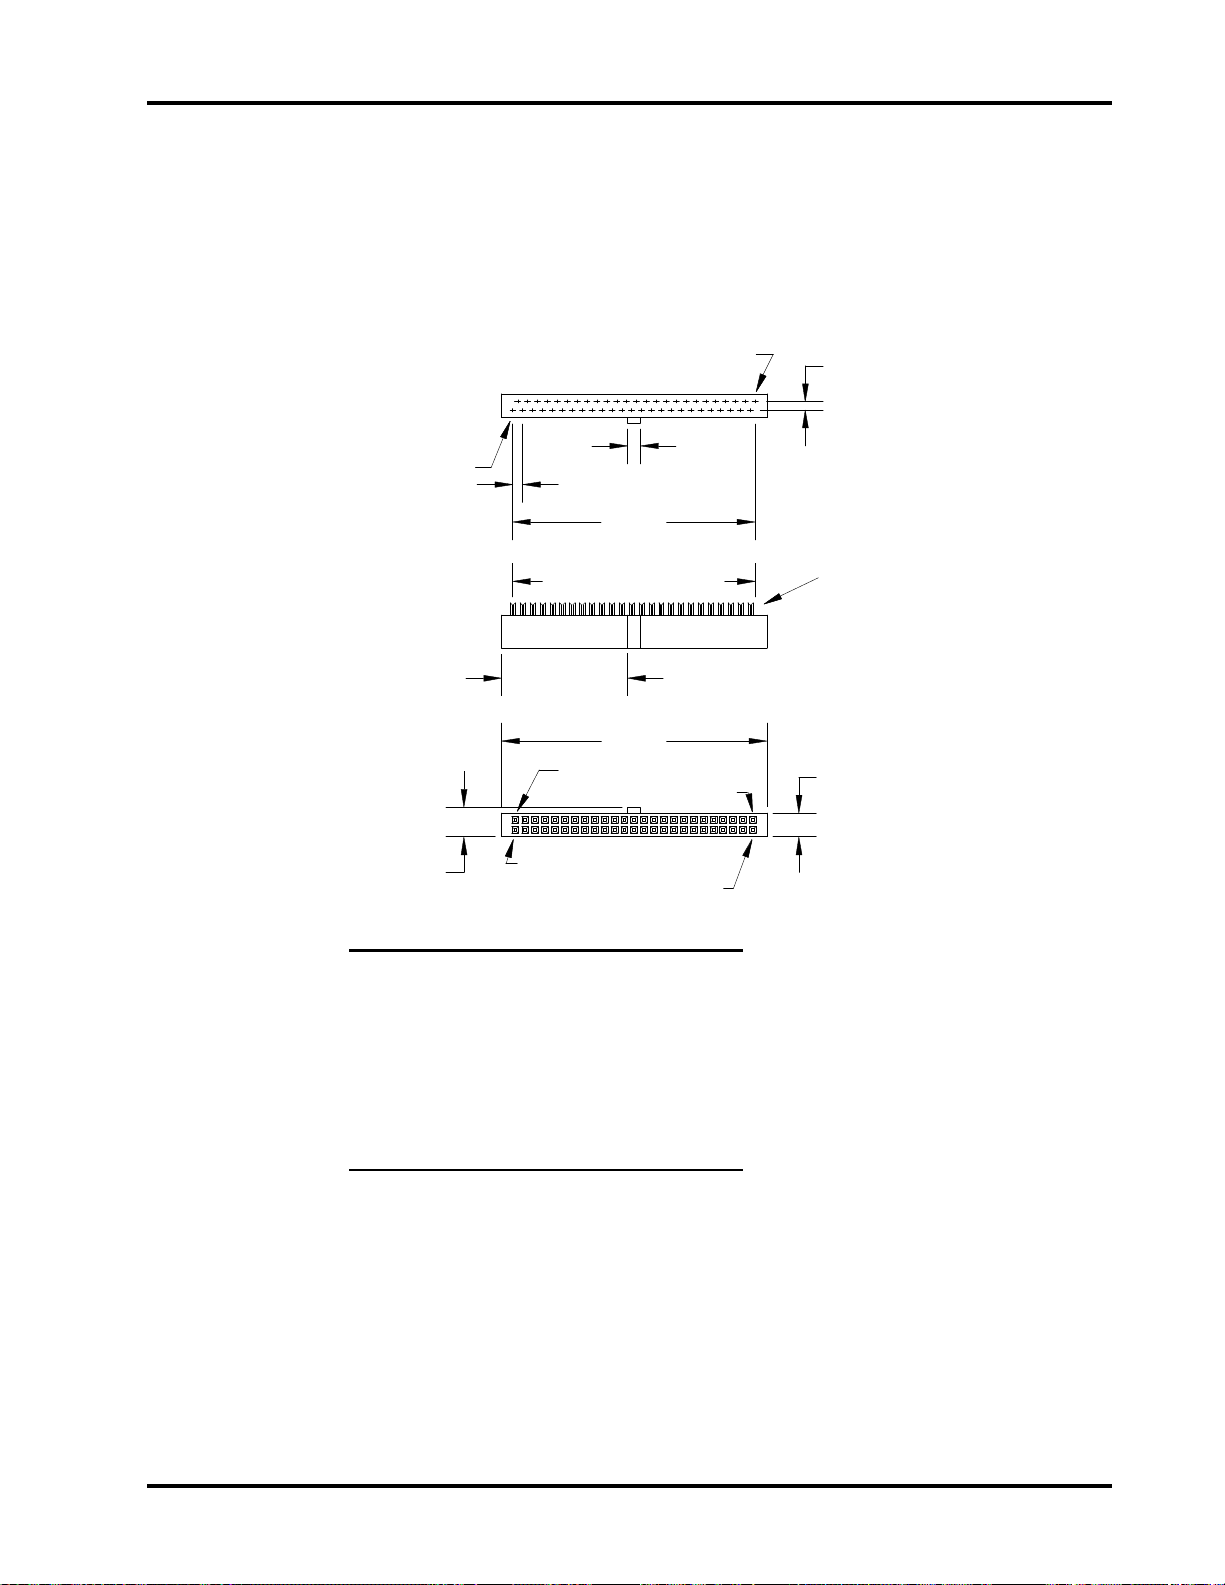
SCSI Physical Characteristics Chapter 5
Socket 49
Socket 50
Socket 2
C8
Front view
Contact 50
C4
C5
C2
Socket 1
C6
See Note 1
Contact 1
C3
Contacts for even
wires are not shown.
C7
Side view
C1
Back view
Connector Requirements
The connector on the drive is a 50-position header which consists of 2 rows of 25
male pins on 0.100 inch centers. The mating connector is a SCSI-2 Non-shielded
Alternative 1, A-cable connector which is shown below:
Figure 5-2
A-Cable Connector
Dimensions Millimeters Inches
C1 2.540 0.100
C2 60.960 2.400
C3 2.540 0.100
C4 3.302 0.130
C5 32.385 1.275
C6 68.072 2.680
C7 6.096 0.240
C8 7.620 0.300
Technical Reference Manual Page 59
Notes:
(1) Fifty contacts on 1.27mm (0.05
inch) staggered spacing =
62.23mm (2.450 inch) [ref.]
(2) Tolerances +0.127mm (0.005
inch) noncumulative unless
specified otherwise.
(3) Connector cover and strain
relief are optional
Page 68
Chapter 5 SCSI Physical Characteristics
Interface Pin Assignments
The pin assignments for the interface connector are shown below:
Table 5-13
Interface Signal Definitions
Pin Signal Pin Signal
01
03
05
07
09
11
13
15
17
19
21
23
25
27
29
31
33
35
37
39
41
43
45
47
49
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
RESERVED
OPEN
RESERVED
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
GND
02
04
06
08
10
12
14
16
18
20
22
24
26
28
30
32
34
36
38
40
42
44
46
48
50
-DB0
-DB1
-DB2
-DB3
-DB4
-DB5
-DB6
-DB7
-DBP
GND
GND
RESERVED
TERMPWR
RESERVED
GND
-ATN
GND
-BSY
-ACK
-RST
-MSG
-SEL
-C/D
-REQ
-I/O
Notes:
1. The minus sign (-) indicates active low.
2. All odd pins except pin 25 must be connected to ground. Pin 25 is left open.
3. Pins marked Reserved are connected to ground.
Page 60 Filepro CFP1060E/CFP1060S/CFP1060W
Page 69
SCSI Physical Characteristics Chapter 5
Interface Timing Requirements
Unless otherwise noted, the delay-time measurements are calculated from signal
conditions existing at the drive's own SCSI bus connector. Normally these
measurements (except cable skew delay) can be made without considering delays
in the cable.
Table 5-14
SCSI Bus Timing Values
Timing Value *
Timing Description fast slow asynch
Arbitration Delay
Bus Clear Delay
Bus Free Delay
Bus Set Delay
Bus Settle Delay
Cable Skew Delay
1
Data Release Delay
Receive Assertion Period
Receive Hold Time
Receive Negation Period
Receive Setup Time
Reset Hold Time
Selection Abort Time
Selection Time-out Delay
System Deskew Delay
Transmit Assertion Period
Transmit Hold Time
Transmit Negation Period
Transmit Setup Time
2.4
µs
800 ns 800 ns 800 ns
800 ns 800 ns 800 ns
1.8
µs
400 ns 400 ns 400 ns
4ns 4ns 4ns
400 ns 400 ns 400 ns
22 ns 70 ns n/a
25 ns 25 ns n/a
22 ns 70 ns n/a
15 ns 15 ns n/a
25
µs
200
µs
2
250 ms 250 ms 250 ms
20 ns 45 ns 45 ns
30 ns 80 ns n/a
33 ns 53 ns n/a
30 ns 80 ns n/a
23 ns 23 ns n/a
2.4
1.8
25
200
µs
µs
µs
µs
2.4
1.8
25
200
µs
µs
µs
µs
Notes:
1
This time does not apply at the SCSI connector of the drive.
2
This is a recommended time. It is not mandatory.
Technical Reference Manual Page 61
Page 70
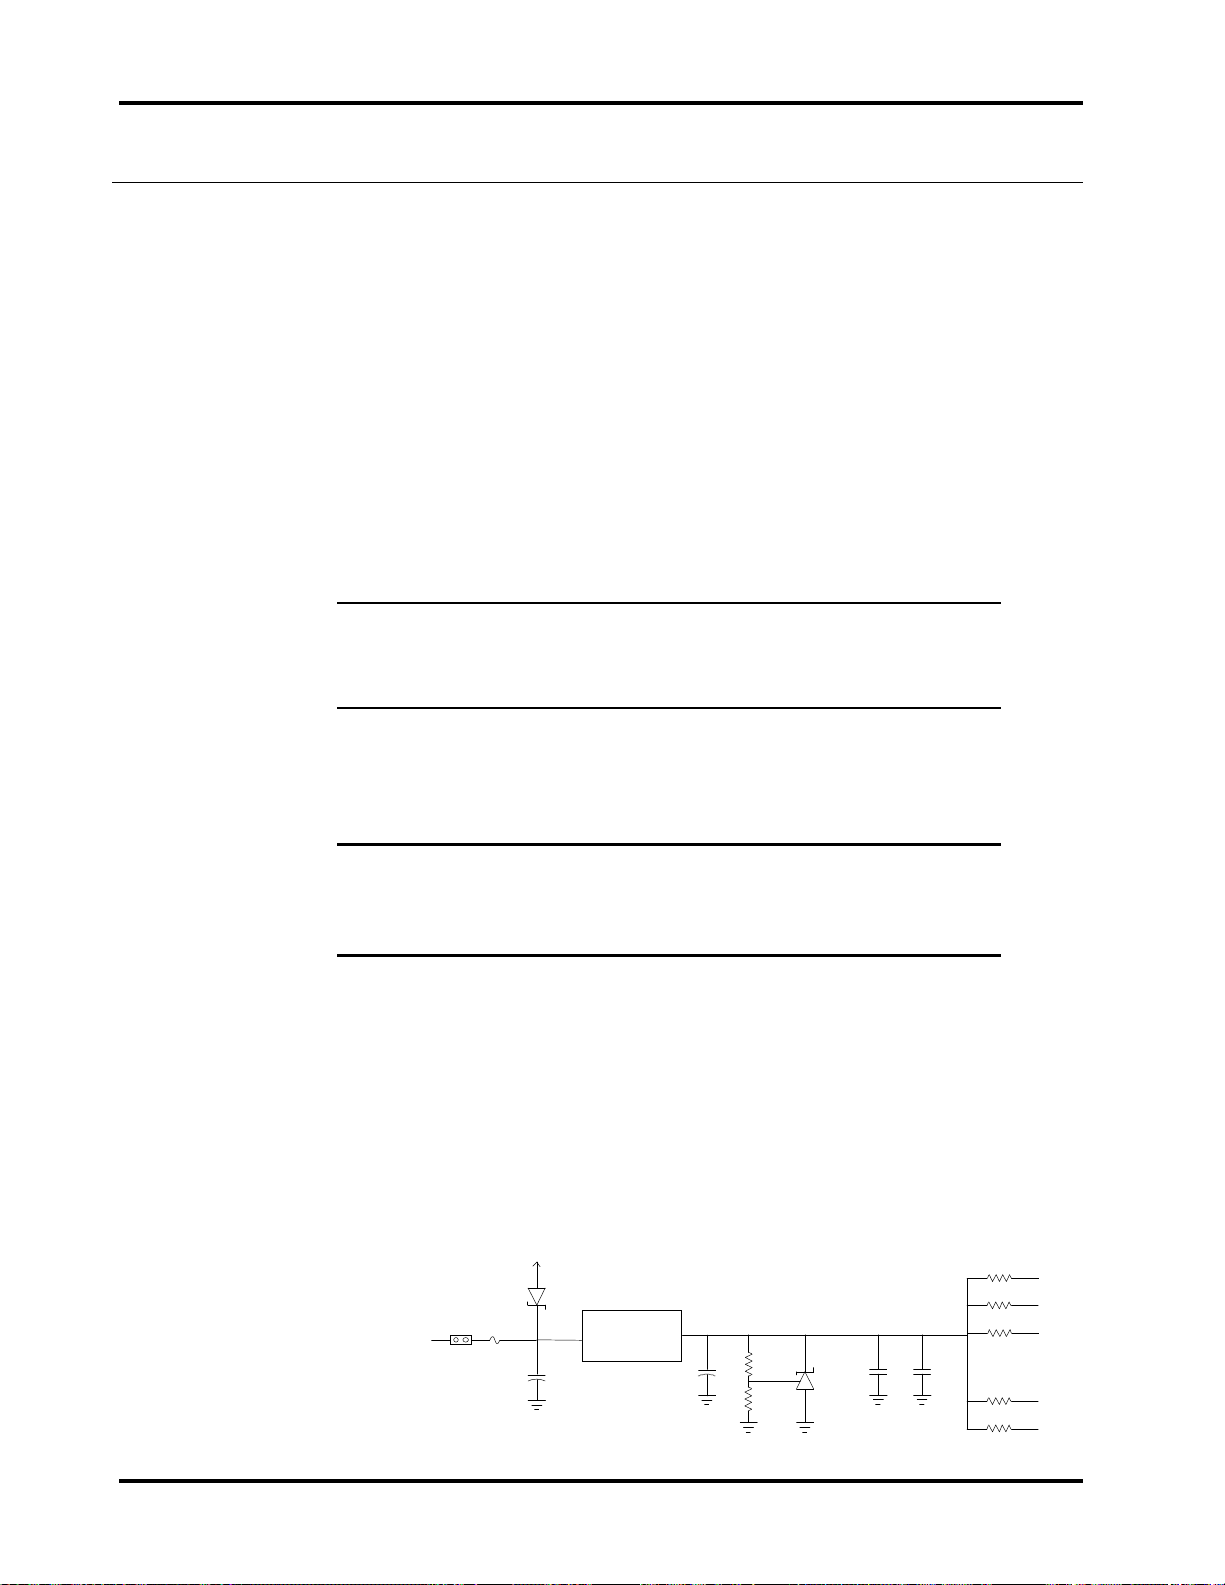
Chapter 5 SCSI Physical Characteristics
Model CFP1060W (Wide, Unitized SCSI-3 P-Connector)
External Terminator Power
Power to the on-board terminators is provided by the higher of the voltage
supplied at Pin #17, 18, 51, & 52, J2 or the voltage level at the 5 Volt power
input to the drive minus one diode drop. The diode prevents back flow of current
to the drive. Termination Power to external terminators can be supplied by the
drive through Pin #17, 18, 51, & 52, J2. The TERMPWR line can be
disconnected from the drive by removing Jumper E8. Table 5-11 describes the
electrical characteristics of the TERMPWR line when it is used to supply power
to an external terminator.
Table 5-15
TERMPWR Electrical Output Characteristics
Signal Characteristic Value
Supply voltage 4.06 VDC to 4.56 VDC
(dependent on power supplied to
the drive)
Minimum source capability: 1500 mA
Table 5-16
TERMPWR Input Electrical Characteristics
Signal Characteristic Value
Input voltage 4.00 VDC to 5.25 VDC
Minimum source capability: 1500 mA (fused at 1500 mA)
Sink current: 1.0 mA maximum, excluding
Internal Termination
This drive provides on-board Alternative 2 active termination for the SCSI bus.
The termination resistors, which are contained in three Single Inline Packs
(SIPs) should be removed from the drive unless it is a SCSI device at a physical
end of the bus. The terminator equivalent circuit is shown below for reference:
Figure 5-2
Terminator Equivalent Circuit
TERMPWR
E8
F1
+5V
Voltage
Regulator
power to the internal terminator.
2.5K
10K
110
: :
: :
: :
-DB0
-DB1
-DB2
-REQ
-I/O
Page 62 Filepro CFP1060E/CFP1060S/CFP1060W
Page 71
SCSI Physical Characteristics Chapter 5
J5 Auxiliary Connector Signal Characteristics
Table 5-17
J5 Auxiliary Interface Electrical Characteristics
State Current Voltage
High
0 < I
< 20 µA
IH
2.5 V < V
< VCC + 0.3 V
IH
Low
Cable Requirements
A 68 conductor cable no more than 3 meters (9.84 feet) cumulative length with at
least 30 AWG wire size and a characteristic impedance of 70 to 100 ohms (84
ohms nominal) is required. In systems which use the fast synchronous transfer
option, the cable should meet the following additional requirements:
Table 5-18
Interface Cable Electrical Characteristics
Specification Value
Signal Attenuation 0.095dB maximum per meter at 5 Mhz
Pair-to-Pair Propagation Delay Delta 0.20 ns maximum per meter
DC Resistance 0.230 ohms maximum per meter at 20° C
0 < I
< -48 mA -0.1 V < VIL < 0.4 V
OH
Technical Reference Manual Page 63
Page 72
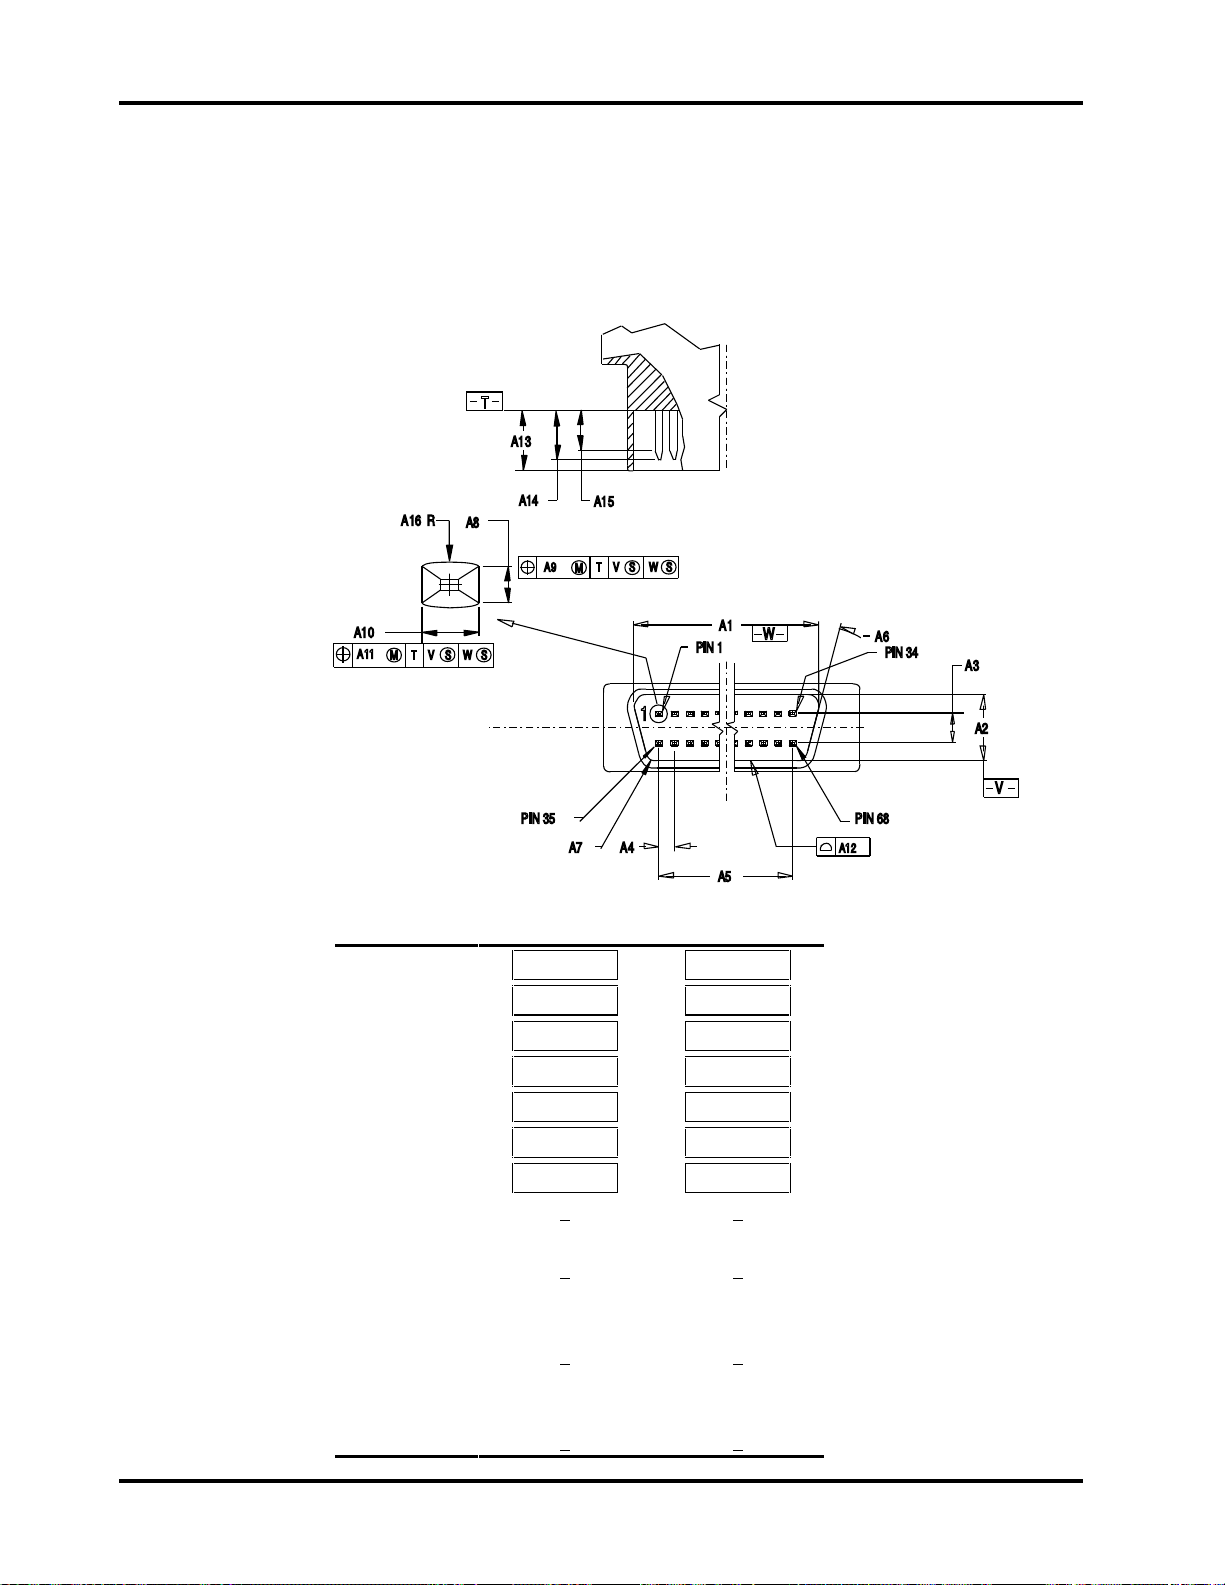
Chapter 5 SCSI Physical Characteristics
Connector Requirements
The connector on the drive is a 68-pin . The mating connector is a SCSI 3 Nonshielded P-cable connector which is shown below:
Figure 5-4
P-Cable Connector
68_5_1
DIMENSIONS Millimeters Inches
A1
A2
A3
A4
A5
A6
A7
A8 0.396 + 0.010 0.0156 + 0.0004
A9 0.23 0.009
A10 0.60 +
A11 0.23 0.009
A12 0.05 0.002
A13 5.15 +
A14 4.39 MAX 0.173 MAX
A15 3.02 MIN 0.119 MIN
A16 1.02 + 0.25 0.040 + 0.010
46.28
5.69
2.54
1.27
41.91
15°
1.04 R
0.03 0.024 + 0.001
0.15 0.203 + 0.006
1.822
0.224
0.100
0.050
1.650
15°
0.041 R
Page 64 Filepro CFP1060E/CFP1060S/CFP1060W
Page 73
SCSI Physical Characteristics Chapter 5
Interface Pin Assignments
The pin assignments for the interface connector are shown below:
Table 5-19
Interface Signal Definitions
Pin Signal Pin Signal
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
1
2
3
4
5
6
7
8
9
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
TERMPWR
TERMPWR
Reserved
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
Ground
35
36
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
-DB(12)
-DB(13)
-DB(14)
-DB(15)
-DB(P1)
-DB(0)
-DB(1)
-DB(2)
-DB(3)
-DB(4)
-DB(5)
-DB(6)
-DB(7)
-DB(P)
Ground
Ground
TERMPWR
TERMPWR
Reserved
Ground
--ATN
Ground
-BSY
-ACK
-RST
-MSG
-SEL
-C/D
-REQ
-I/O
-DB(8)
-DB(9)
-DB(10)
-DB(11)
Notes:
1. The minus sign (-) indicates active low.
2. Pins marked Reserved are not connected.
Technical Reference Manual Page 65
Page 74
Chapter 5 SCSI Physical Characteristics
Interface Timing Requirements
Unless otherwise noted, the delay-time measurements are calculated from signal
conditions existing at the drive's own SCSI bus connector. Normally these
measurements (except cable skew delay) can be made without considering delays
in the cable.
Table 5-20
SCSI Bus Timing Values
Timing Value *
Timing Description fast slow asynch
Arbitration Delay
Bus Clear Delay
Bus Free Delay
Bus Set Delay
Bus Settle Delay
Cable Skew Delay
1
Data Release Delay
Receive Assertion Period
Receive Hold Time
Receive Negation Period
Receive Setup Time
Reset Hold Time
Selection Abort Time
Selection Time-out Delay
System Deskew Delay
Transmit Assertion Period
Transmit Hold Time
Transmit Negation Period
Transmit Setup Time
2.4
µs
800 ns 800 ns 800 ns
800 ns 800 ns 800 ns
1.8
µs
400 ns 400 ns 400 ns
4ns 4ns 4ns
400 ns 400 ns 400 ns
22 ns 70 ns n/a
25 ns 25 ns n/a
22 ns 70 ns n/a
15 ns 15 ns n/a
25
µs
200
µs
2
250 ms 250 ms 250 ms
20 ns 45 ns 45 ns
30 ns 80 ns n/a
33 ns 53 ns n/a
30 ns 80 ns n/a
23 ns 23 ns n/a
2.4
1.8
25
200
µs
µs
µs
µs
2.4
1.8
25
200
µs
µs
µs
µs
Notes:
1
This time does not apply at the SCSI connector of the drive.
2
This is a recommended time. It is not mandatory.
Page 66 Filepro CFP1060E/CFP1060S/CFP1060W
Page 75
SCSI Command Implementation
6
This section contains a brief summary of the SCSI Interface implemented in the
drive. For additional details regarding command descriptions, please refer to
the Ninth Generation SCSI Interface Manual.
SCSI Command Summary
Following is a list of commands that the drive supports:
Format Unit 04H
Inquiry 12H
Mode Select 15H
Mode Sense 1AH
Read (6) 08H
Read Buffer 3CH
Read Capacity 25H
Read Defect Data 37H
Read Extended (10) 28H
Read Long 3EH
Reassign Blocks 07H
Receive Diagnostics 1CH
Release 17H
Request Sense 03H
Reserve 16H
Re-zero Unit 01H
Seek (6) 0BH
Seek Extended (10) 2BH
Send Diagnostic 1DH
Start/Stop Unit 1BH
Test Unit Ready 00H
Verify 2FH
Write (6) 0AH
Write Extended (10) 2AH
Write and Verify 2EH
Write Buffer 3BH
Write Long 3FH
Technical Reference Manual Page 67
Page 76
Chapter 6 SCSI Command Implementation
Drive Dependent SCSI Data
Format Drive Page - 03
H
The Format Drive page contains parameters which specify the medium format.
Table 6-1
Format Drive Page Format
Bit
76543210
Byte
0
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21-23
Rsvd Rsvd Page Code = 03
Page Length = 16
H
Tracks per Zone (MSB)
(00
)
H
Tracks per Zone (LSB)
(01
)
H
Alternate Sectors per Zone (MSB)
(00
)
H
Alternate Sectors per Zone (LSB)
(01
)
H
Alternate Tracks per Zone (MSB)
Alternate Tracks per Zone (LSB)
Alternate Tracks per Logical Unit (MSB)
Alternate Tracks per Logical Unit (LSB)
Sectors per Track (MSB)
(00
)
H
Sectors per Track (LSB)
(40*
)
H
Data Bytes per Physical Sector (MSB)
(02
)
H
Data Bytes per Physical Sector (LSB)
(00
)
H
Interleave (MSB)
(00
)
H
Interleave (LSB)
(01
)
H
Track Skew Factor (MSB)
(00
)
H
Track Skew Factor (LSB)
(05
)
H
Cylinder Skew Factor (MSB)
(00
)
H
Cylinder Skew Factor (LSB)
(0C
)
H
SSEC HSEC
(1)
RMB SURF Reserved
Reserved
H
* Varies depending on active notch.
Page 68 Filepro CFP1060E/CFP1060S/CFP1060W
Page 77
SCSI Physical Characteristics Chapter 6
Tracks Per Zone: Defines the number of tracks per zone to use in dividing the
capacity of the drive for the purpose of allocating alternate sectors. A value of
zero means that one zone is defined for the entire drive.
Alternate Sectors Per Zone: Defines the number of spare sectors per zone the
drive reserves for defect handling. Not supported. Must be set to zero.
Alternate Tracks Per Logical Unit: Not supported. Must be set to zero.
Sectors Per Track: Defines the number of physical sectors per track. The
number includes the one alternate sector per track the drive allocates. The value
reported for the number of sectors per track is dependent on the active notch
value.
Data Bytes Per Physical Sector: Defines the number of data bytes per
physical sector.
Interleave: Defines the interleave value used by the drive.
Track Skew Factor: Defines the number of physical sectors between the last
logical block of one track, and the first logical block on the next sequential track
of the same cylinder.
Cylinder Skew Factor: Specifies the number of physical sectors between the
last logical block of one cylinder and the first logical block on the next sequential
cylinder.
SSEC (Soft Sector Format): Set to zero to indicate the drive does not support
a soft sector format.
HSEC (Hard Sector Format): Set to one to indicate the drive supports a hard
sector format.
RMB (Removable Media): Set to zero to indicate the drive does not have
removable media.
SURF (Surface Format): The SURF bit is set to zero, meaning the drive
allocates progressive addresses to all logical blocks within a cylinder prior to
allocating addresses on the next cylinder.
Technical Reference Manual Page 69
Page 78
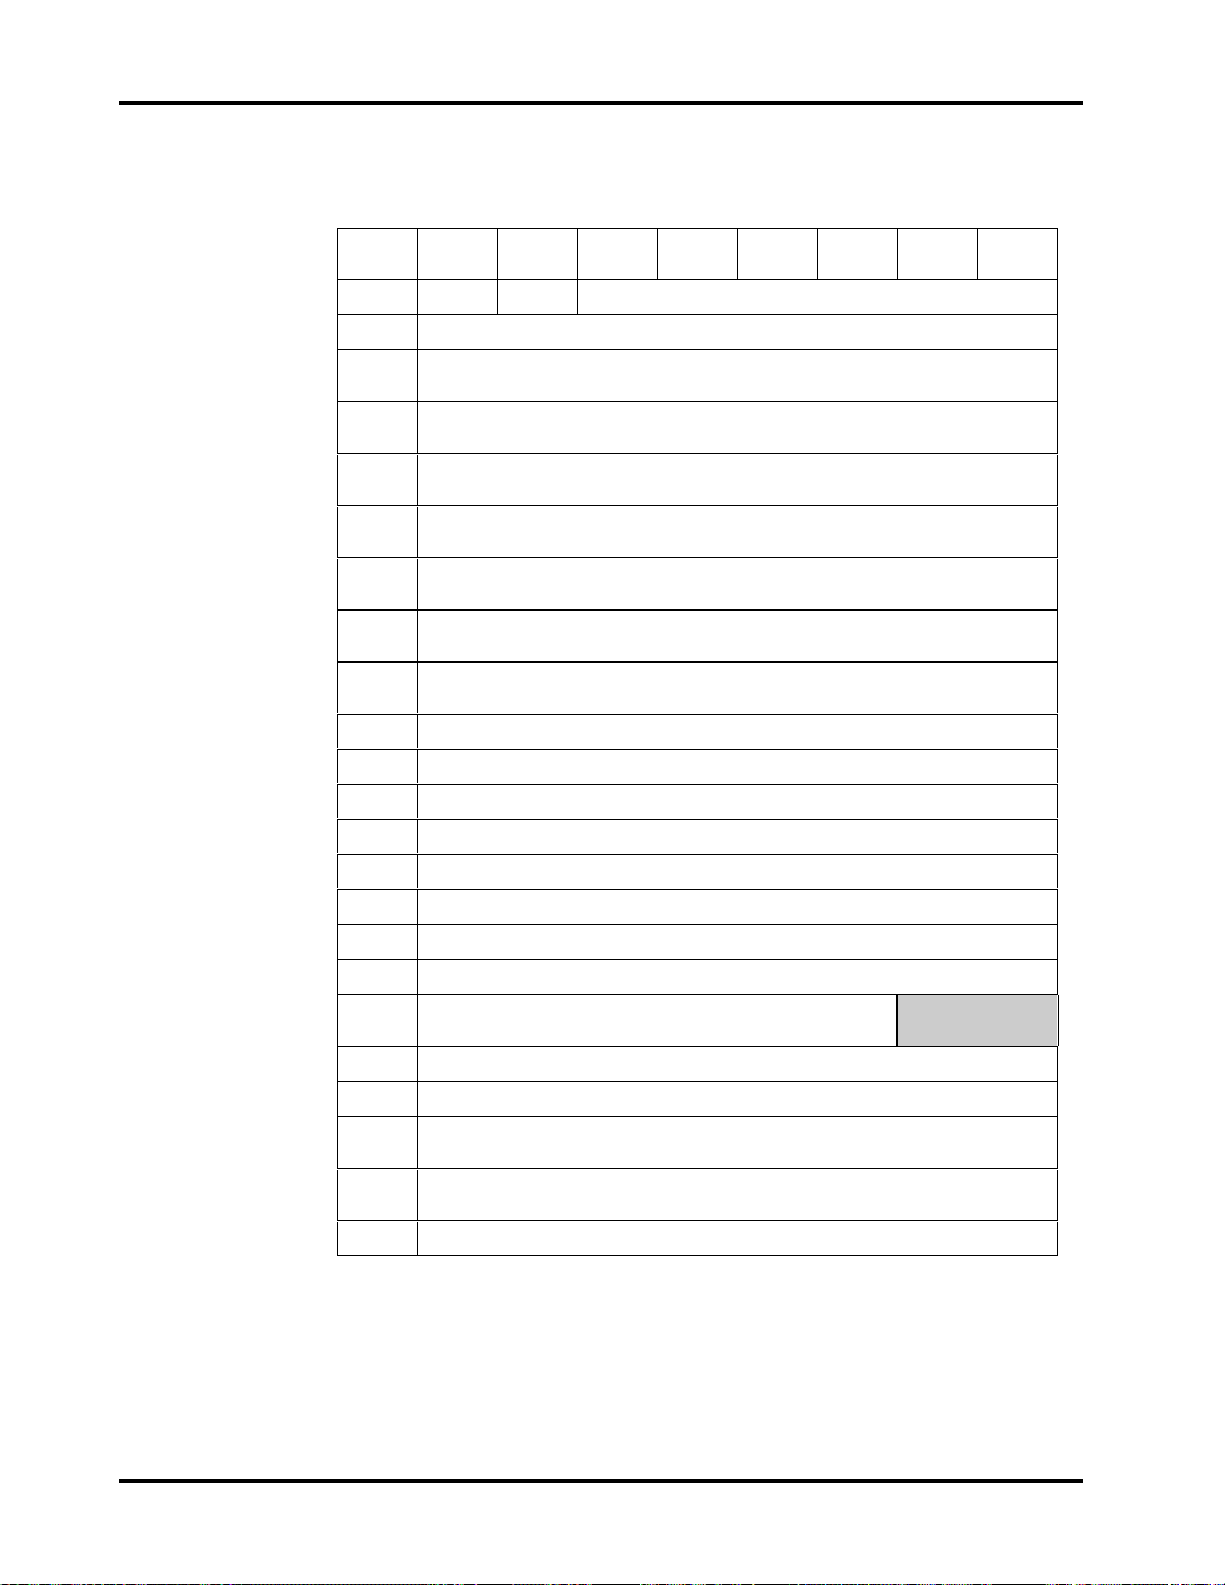
Chapter 6 SCSI Command Implementation
Drive Geometry Page - 04
Table 6-2
Drive Geometry Page
Bit
76543210
Byte
0
Rsvd Rsvd Page Code = 04
1
2
3
4
5
6
7
8
9
Starting Cylinder - Write Precompensation (MSB)
Starting Cylinder - Write Precompensation
Starting Cylinder - Write Precompensation (LSB)
Starting Cylinder - Reduced Write Current (MSB)
H
Page Length = 16
Number of Cylinders (MSB)
(00
)
H
Number of Cylinders
(0A
)
H
Number of Cylinders (LSB)
(C4
)
H
Number of Heads
(08
)
H
(00
)
H
(06
)
H
(00
)
H
H
H
10
11
12
13
14
15
16
17
Starting Cylinder - Reduced Write Current
Starting Cylinder - Reduced Write Current (LSB)
Drive Step Rate (MSB)
Drive Step Rate (LSB)
Landing Zone Cylinder (MSB)
Landing Zone Cylinder
Landing Zone Cylinder (LSB)
Reserved
RPL
(0H)
18
19
20
21
22-23
Rotational Offset
Reserved
Medium Rotation Rate (MSB)
(15
)
H
Medium Rotation Rate (LSB)
(18
)
H
Reserved
* Varies depending on active notch.
Only one copy of this page is maintained. There is only one changeable field,
RPL. All other fields are described in the MODE SENSE Command.
Page 70 Filepro CFP1060E/CFP1060S/CFP1060W
Page 79
SCSI Physical Characteristics Chapter 6
RPL (Rotational Position Locking): Enables spindle synchronization.
Setting either bit 0 or 1, or both, causes multiple drives which have their spindle
synchronization (SS) pins daisy chained together to synchronize their spindles.
Notch and Partition Parameters Page - 0C
H
The Notch and Partition Parameters Page contains information which pertains
to each notch of the drive. Each section of the drive with a different number of
logical blocks per cylinder is referred to as a notch or zone. Only one copy of this
page is maintained. The only changeable field in this page is Active Notch.
Technical Reference Manual Page 71
Page 80
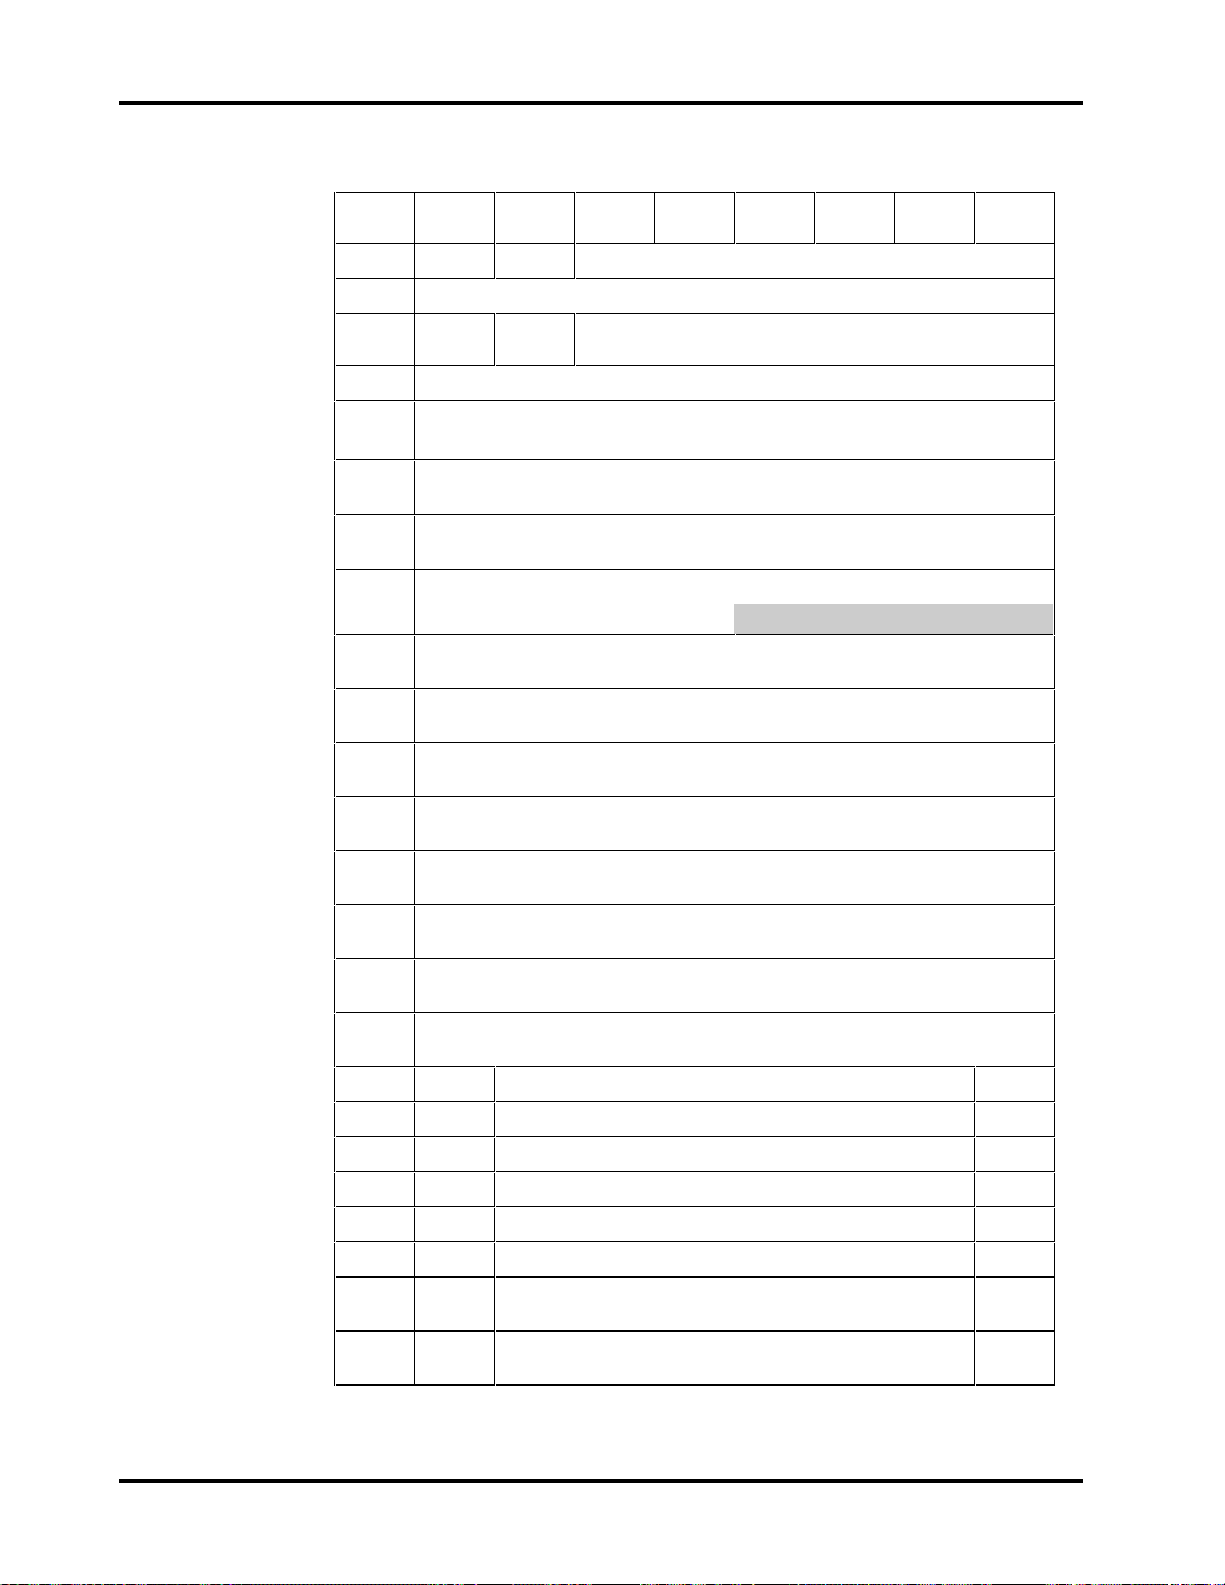
Chapter 6 SCSI Command Implementation
Table 6-3
Notch and Partition Parameters Page Format
Bit
Byte
76543210
0
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
Rsvd Rsvd Page Code - OC
ND
Page Length = 16
LPN Reserved
H
H
(1)
Reserved
Maximum Number of Notches (MSB)
)
(00
H
Maximum Number of Notches (LSB)
(09
)
H
Active Notch (MSB)
(00
)
H
Active Notch (LSB)
(0H) (9*H)
Starting Boundary (MSB)
(00*
)
H
Starting Boundary
(0A*
)
H
Starting Boundary
(65*
)
H
Starting Boundary (LSB)
(00*
)
H
Ending Boundary (MSB)
(00*
)
H
Ending Boundary
(0A*
)
H
Ending Boundary
(CB*
)
H
Ending Boundary (LSB)
(00*
)
H
3F Pages Notched (MSB) 38
17
18
19
20
21
22
23
37 Pages Notched 30
2F Pages Notched 28
27 Pages Notched 20
1F Pages Notched 18
17 Pages Notched 10
0F
07
Pages Notched
(10
)
H
Pages Notched (LSB)
(08
)
H
08
00
* Varies depending on active notch.
Page 72 Filepro CFP1060E/CFP1060S/CFP1060W
Page 81
SCSI Physical Characteristics Chapter 6
ND (Notched Drive): If set to zero, the drive is not notched and all other
parameters in this page are returned as zeros. If set to one, the drive is notched
and this page defines the starting and ending boundaries for each active notch.
This parameter is always set to one.
LPN (Logical or Physical Notch): When set to zero, indicates the notch
boundaries are physical addresses (i.e., cylinder and head). An LPN bit of one is
not supported.
The Maximum Number of Notches field indicates the maximum number of
notches supported by the drive.
The Active Notch field indicates which notch is being referred to by this and
subsequent MODE SELECT and MODE SENSE commands, until changed by a
later MODE SELECT command. Active notches are numbered beginning from
one up to the maximum number of notches.
The Starting Boundary field indicates the beginning of the active notch; the
three most significant bytes represent the cylinder number and the least
significant byte represents the head number.
The Ending Boundary field indicates the ending of the active notch; the three
most significant bytes represent the cylinder and the least significant byte
represents the head number.
The Pages Notched field is a bit map of the MODE SELECT page codes which
indicates the pages containing parameters that are changed for different
notches. The most significant bit of this field corresponds to page code 3F and
the least significant bit represents page code 0. If a bit is a one, the
corresponding MODE SELECT page contains parameters that are changed for
different notches. If a bit is a zero, the corresponding MODE SELECT page
parameters are constant for all notches.
Technical Reference Manual Page 73
 Loading...