

Page 1

User manual
10x Zoom EO + IR Dual Sensor Object Tracking Camera Gimbal
Images are for reference only, please subject to the actual product.
MINI Z10TIR
Page 2

Mini Z10TIR Pinpoint-precision Gimbal
1. …………… 2
2. ………………………………………………………2
3. Gimbal description……………………………………………………………………3
4. Packing list …… ………………………………………………………………………4
5. Gimbal dimension …………………………………………………………………4
6. Installing ………………………………………………………………………………5
7. Mechanics@Electronic characteristics … … … … … … … … … … … … … …5
8. Working characteristics ……………………………………………………………5
9. Gimbal’s signal wire box ………………………………………………………6
Gimbal introduction ………………………… ………………………
Object tracking function …
-1-
Contents
640 19mm Thermal Imager Parameter
10x Visible Light Camera Specifications
1. ………………………10640 19mm Thermal Imager Parameter ………………
1. ………………………1110x zoom visible light camera specifications…………
…
…
……
…
……
…
…
…
…
Page 3

Object Tracking Function
Gimbal Introduction
MINI 10TIR is a pinpoint-precision professional 3-axis gimbal which features
high stability, small size, light weight and low power consumption. The 3-axis
gimbal based on FOC motor control technology, adopts pinpoint-precision
encoder in each motor.
The speed of MINI 10TIR gimbal is adjustable, LOW speed mode is used
for large zoom range, the control will be more accurate; Fast speed mode
is used for small zooming range, which makes the gimbal control sensitive
and quick. Also the one-key to center function will allow the gimbal return
to initial position automatically and rapidly.
-2-
1. Function description
2. Tracking Performance
Build-in normalization, cross-correlation and tracking algorithm,
combining with object missing recapture algorithm, achieve stable
track of the target.
Support custom characters of user OSD, adaptive gate, cross cursor,
tracking information display.
1) Update rate of deviation pixel 50Hz
2) Output delay of deviation pixel <15ms
3) Minimum object contrast 5%
4) The minimal signal-to-noise ratio (SNR) 4
5) Minimum object size 16*16 pixel
6) Maximum object size 160*160 pixel
7) Tracking speed 32 pixel/frame
8) The mean square root values of pulse noise in the object position<0.5
pixel
9) Object memory time 100 frames
MINI Z10TIR supports PWM, S.BUS and serial command control, suitable
for close range remote control or remote data command control.
Page 4

!
Please make sure that the motor is not stopped by any object during
the rotation, if the gimbal is blocked during rotation, please remove
the obstruction immediately.
-3-
Gimbal Description
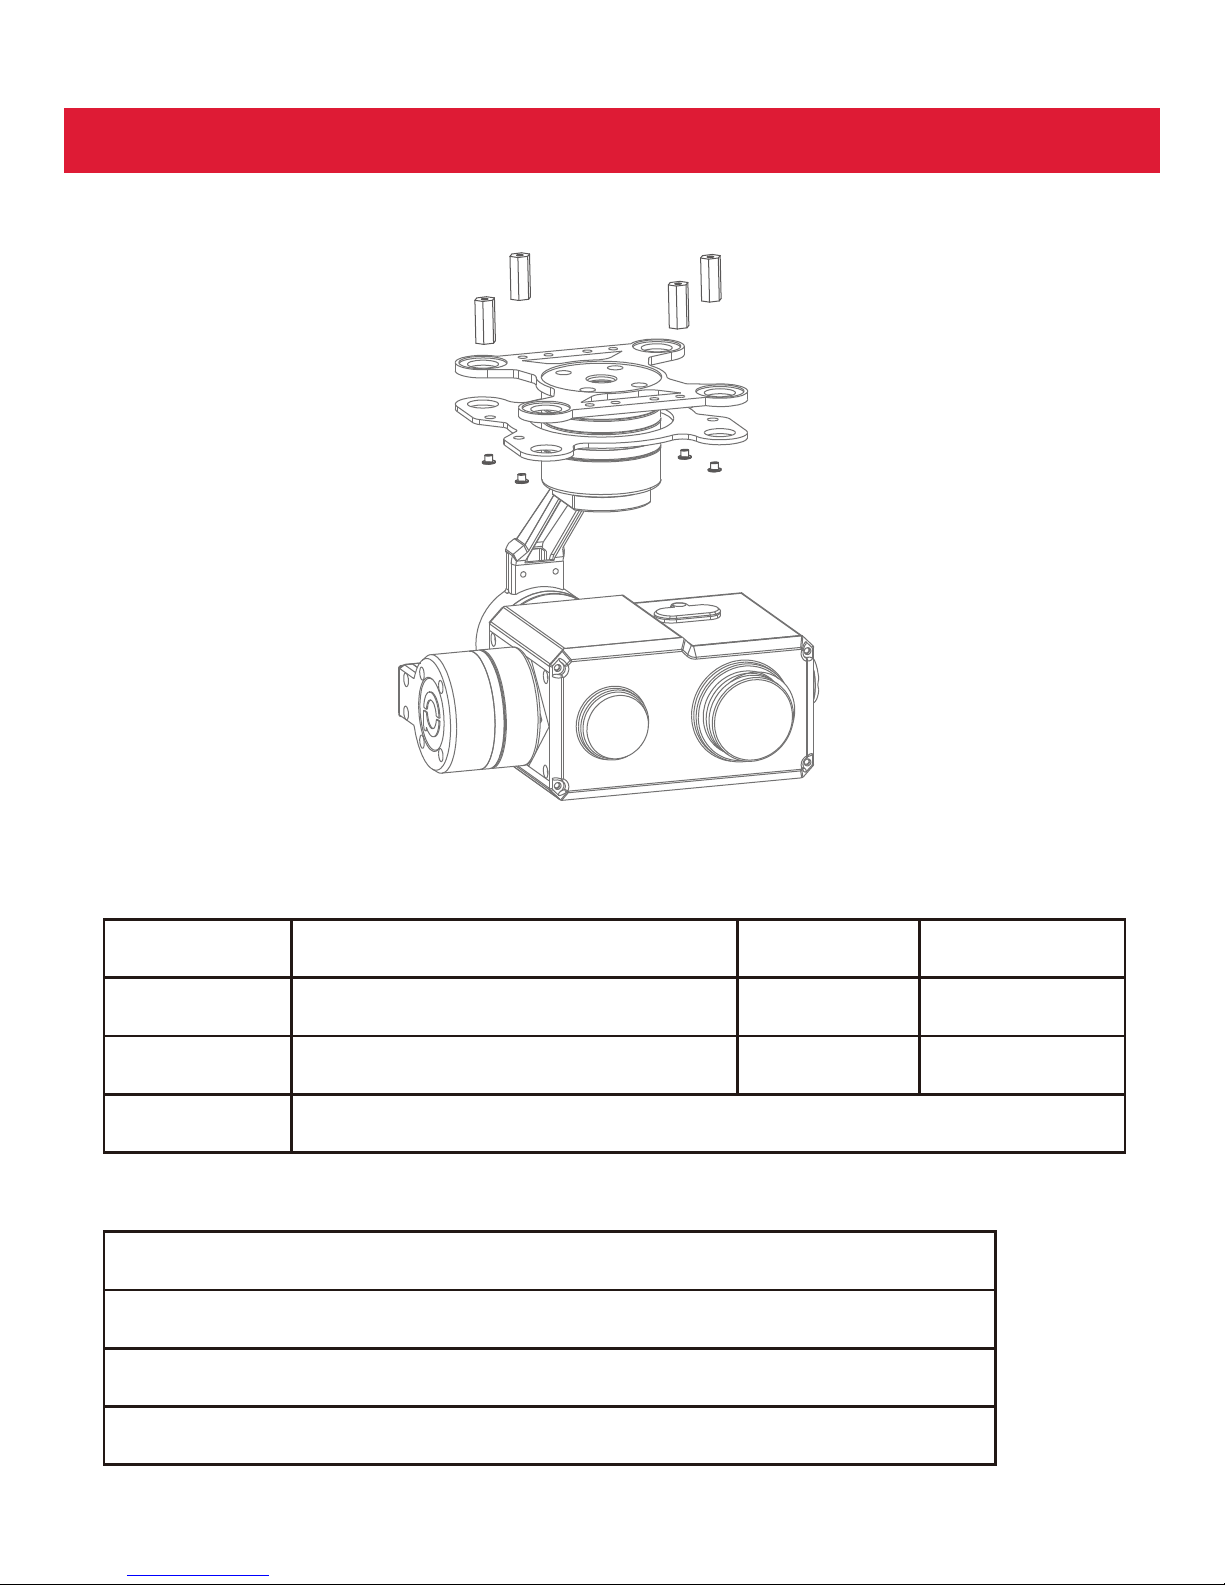
[1] Upper damping board
[2]
[3]
[4]
Lower damping board
YAW axis motor
Roll axis motor
[5] Pitch axis motor
10x HD zoom camera
19mm 640 thermal infrared camera
[6]
[7]
[7]
[6]
[1]
[2]
[4]
[3]
[5]
Page 5
Screw pack*1
(M3*5mm button head hexagon screw*4)
Packing list
Gimbal*1 Screw pack*1
Copper cylindersr*4 Damping balls*4
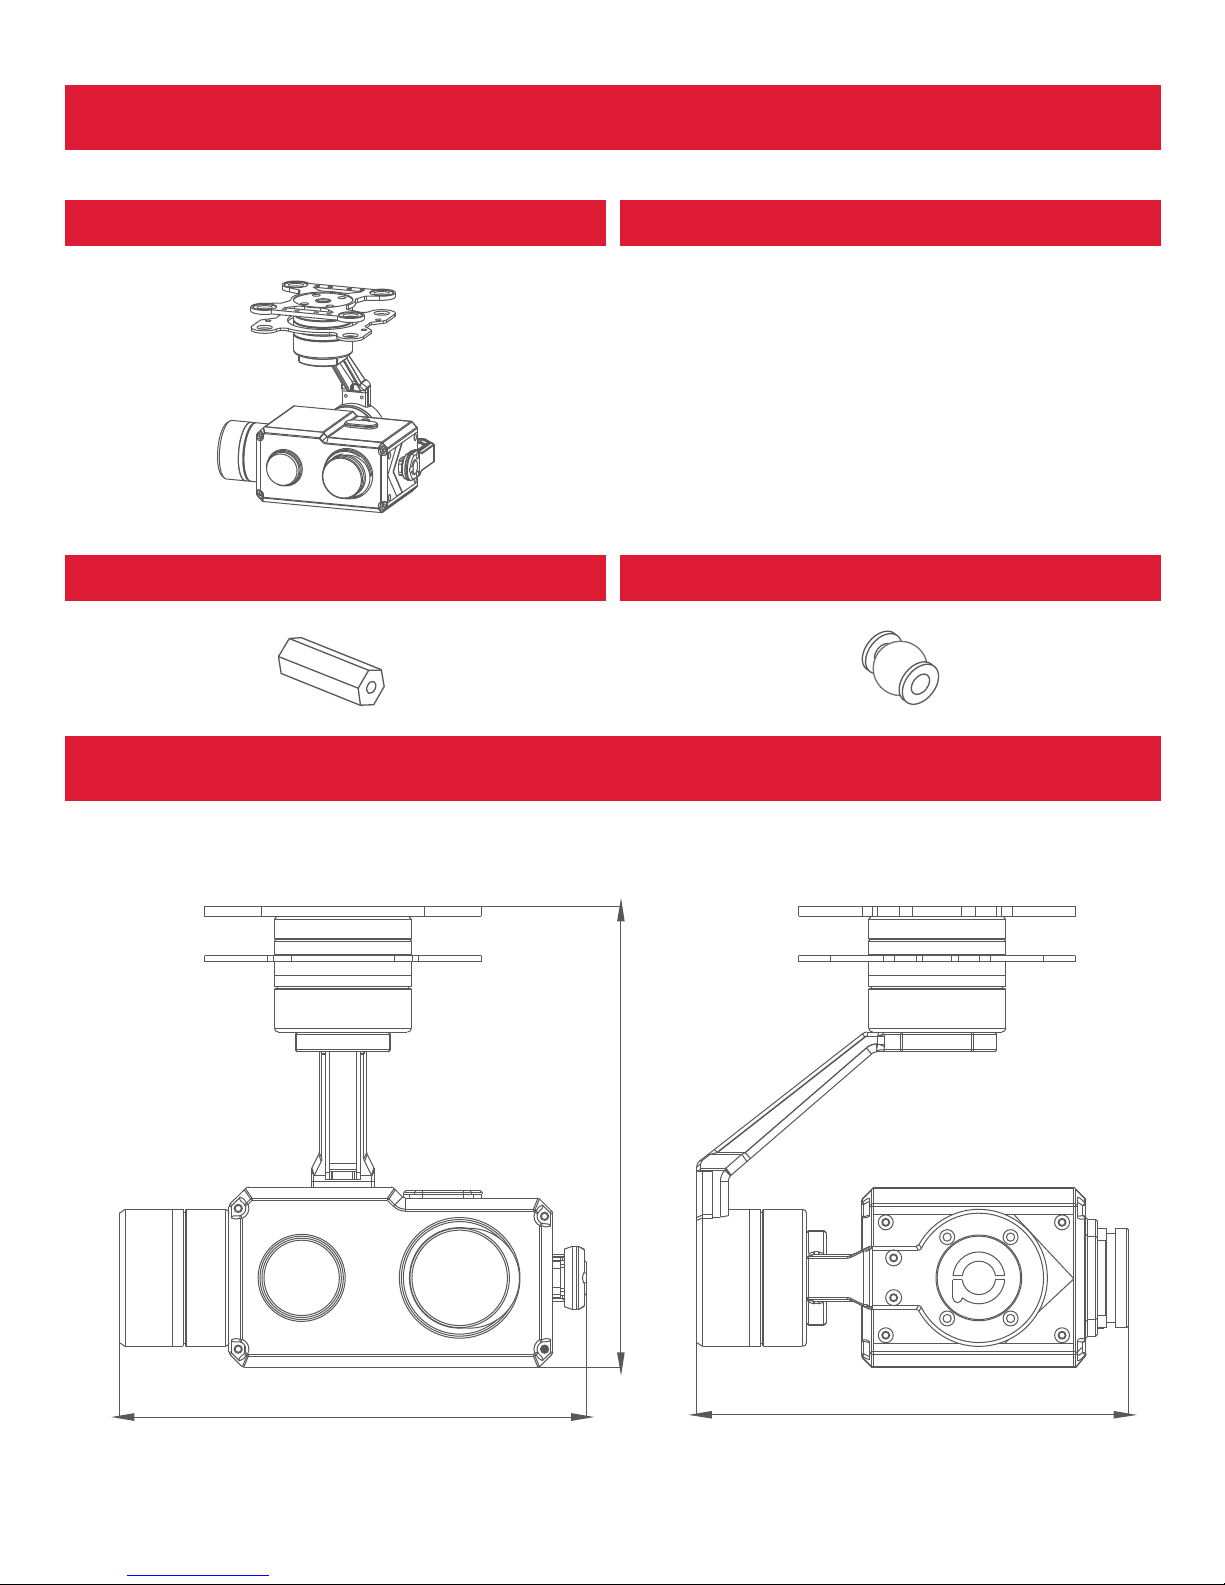
Gimbal Dimension
Unit :mm
-4-
118 109
120
Page 6
Input voltage
Dynamic current
Size
3S~ 4S
500m A@12V
L118 *W 109*H120mm
Idle current
Working
environment temp
Weight
450mA@12V
-10℃ ~ +60℃
490g
Working Characteristics
Mechanics@Electronic Characteristics
Installing
Pitch/Tilt: Pitch angle range of action : ±90
Roll: Roll angle range of action : ±85°
Yaw/Pan: Yaw angle range of action : ±170°
-5-
Vibration angle: Pitch/Roll: ±0.01°, Yaw:±0.01°
Temp
-30℃~+80℃
Page 7
-6-
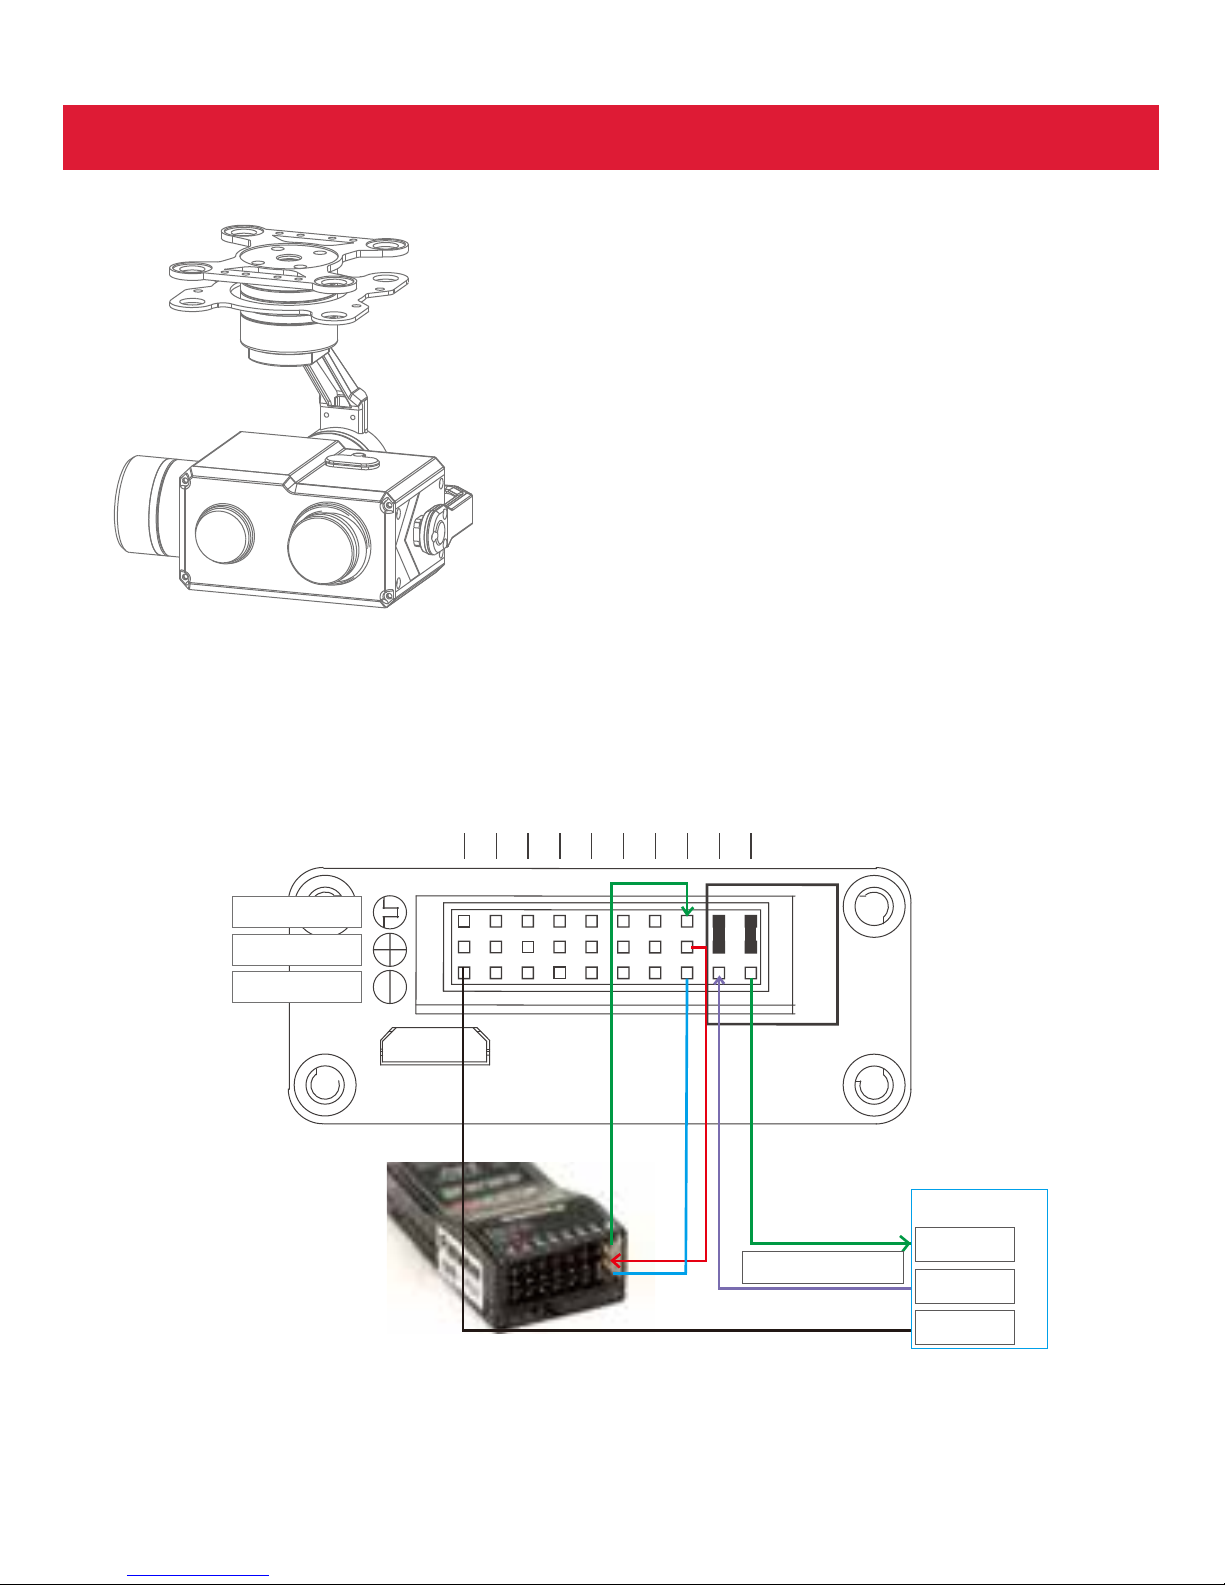
Connection of Control Box and Wiring Instruction
HDMI: micro HDMI OUTPUT
1080P 60fps default
SD card: max 128G, class10
FAT32 or exFAT format
USB
1 2 3
S.bus/Rx
Roll/Tx
Pitch
Yaw
Mode
Zoom
Focus
Pic/Rec
Multi
Av
PWM in
5V output
GND
TTL 9600/8/1/N
USER BOARD
RX
TX
GND
Page 8
-7-
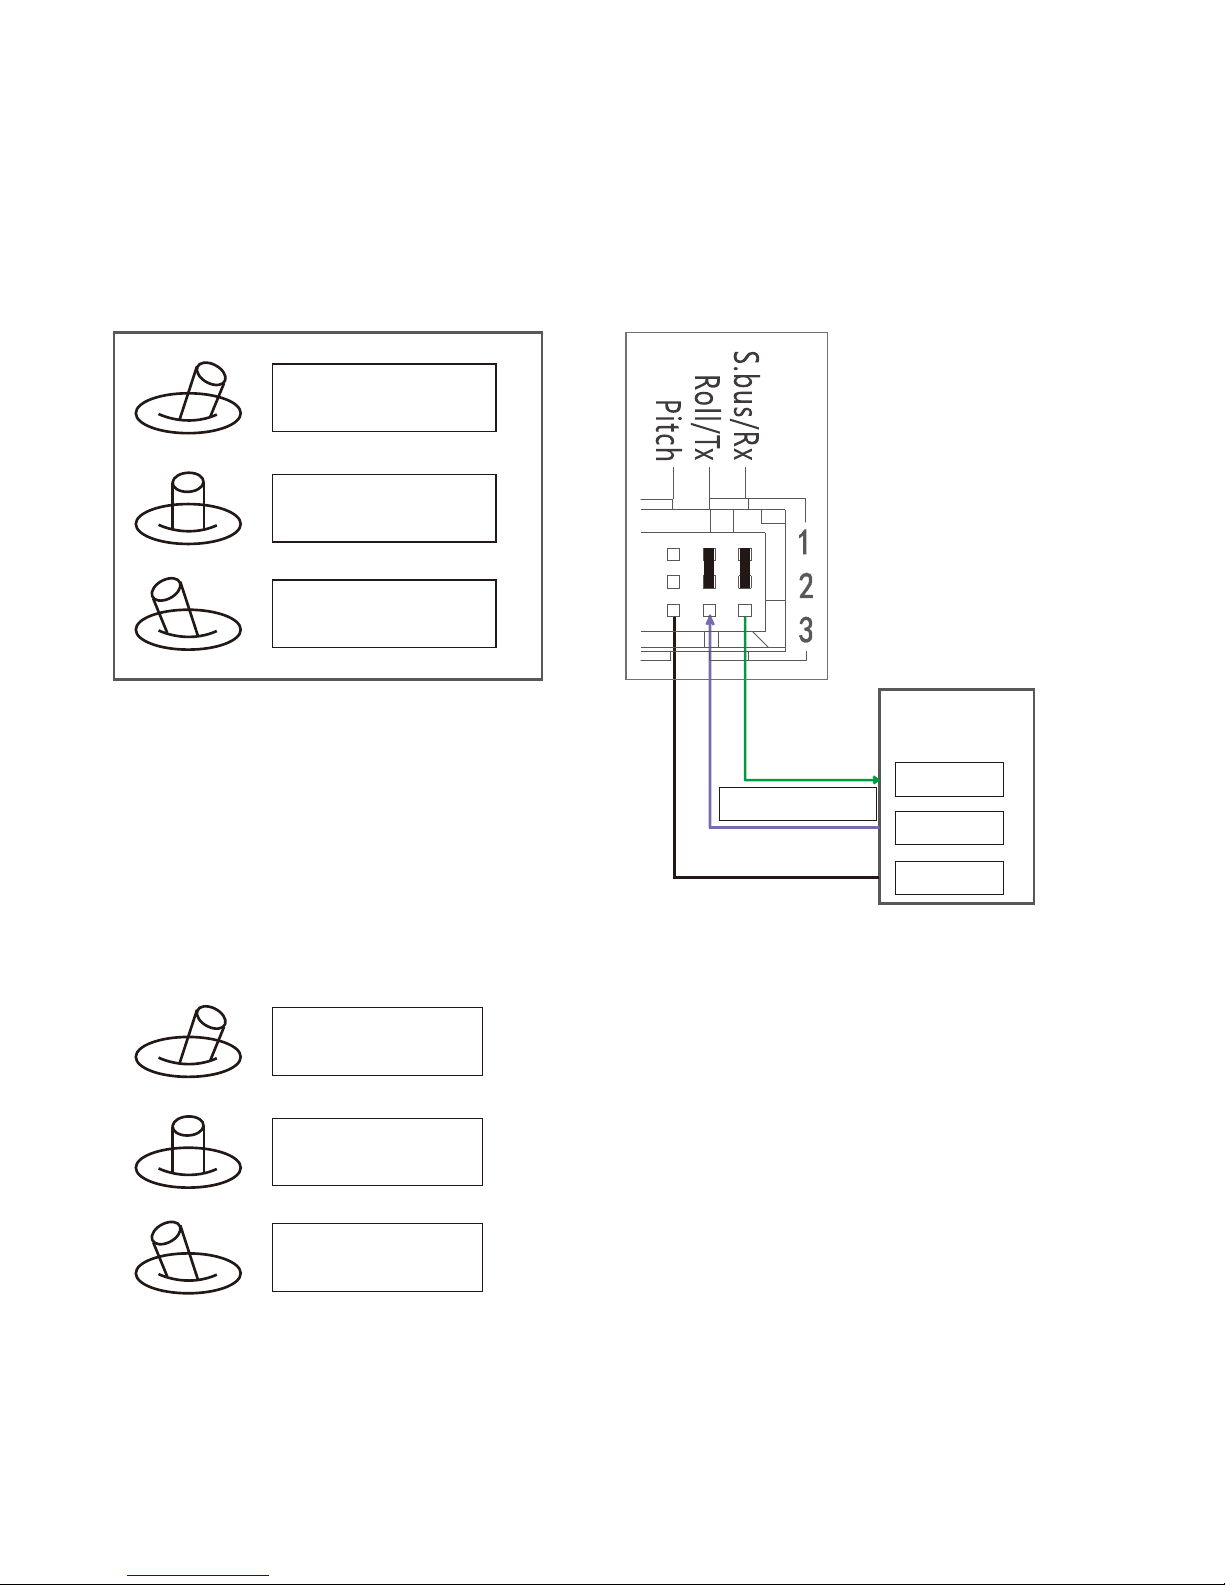
S.bus/Rx: connect to Rx2 for track function.
Roll/ Tx: connect to Tx2 for track function.
Pitch: PWM in, pitch control
1. Pitch up
2. Pitch stop
3.
Pitch down
We have p ro t o co l f o r
co n t ro l t h e g i m b a l
an d cam er a , p l ease
con t act o u r t ech n i cal
su p p o r t f o r d e t a i l
d o c.
USER BOARD /
GPS module
TX
GND
RX
TT L 115200/8 /1/N
Yaw:PWM in, Yaw control
1. Yaw right
2. Yaw stop
3. Yaw left
Page 9
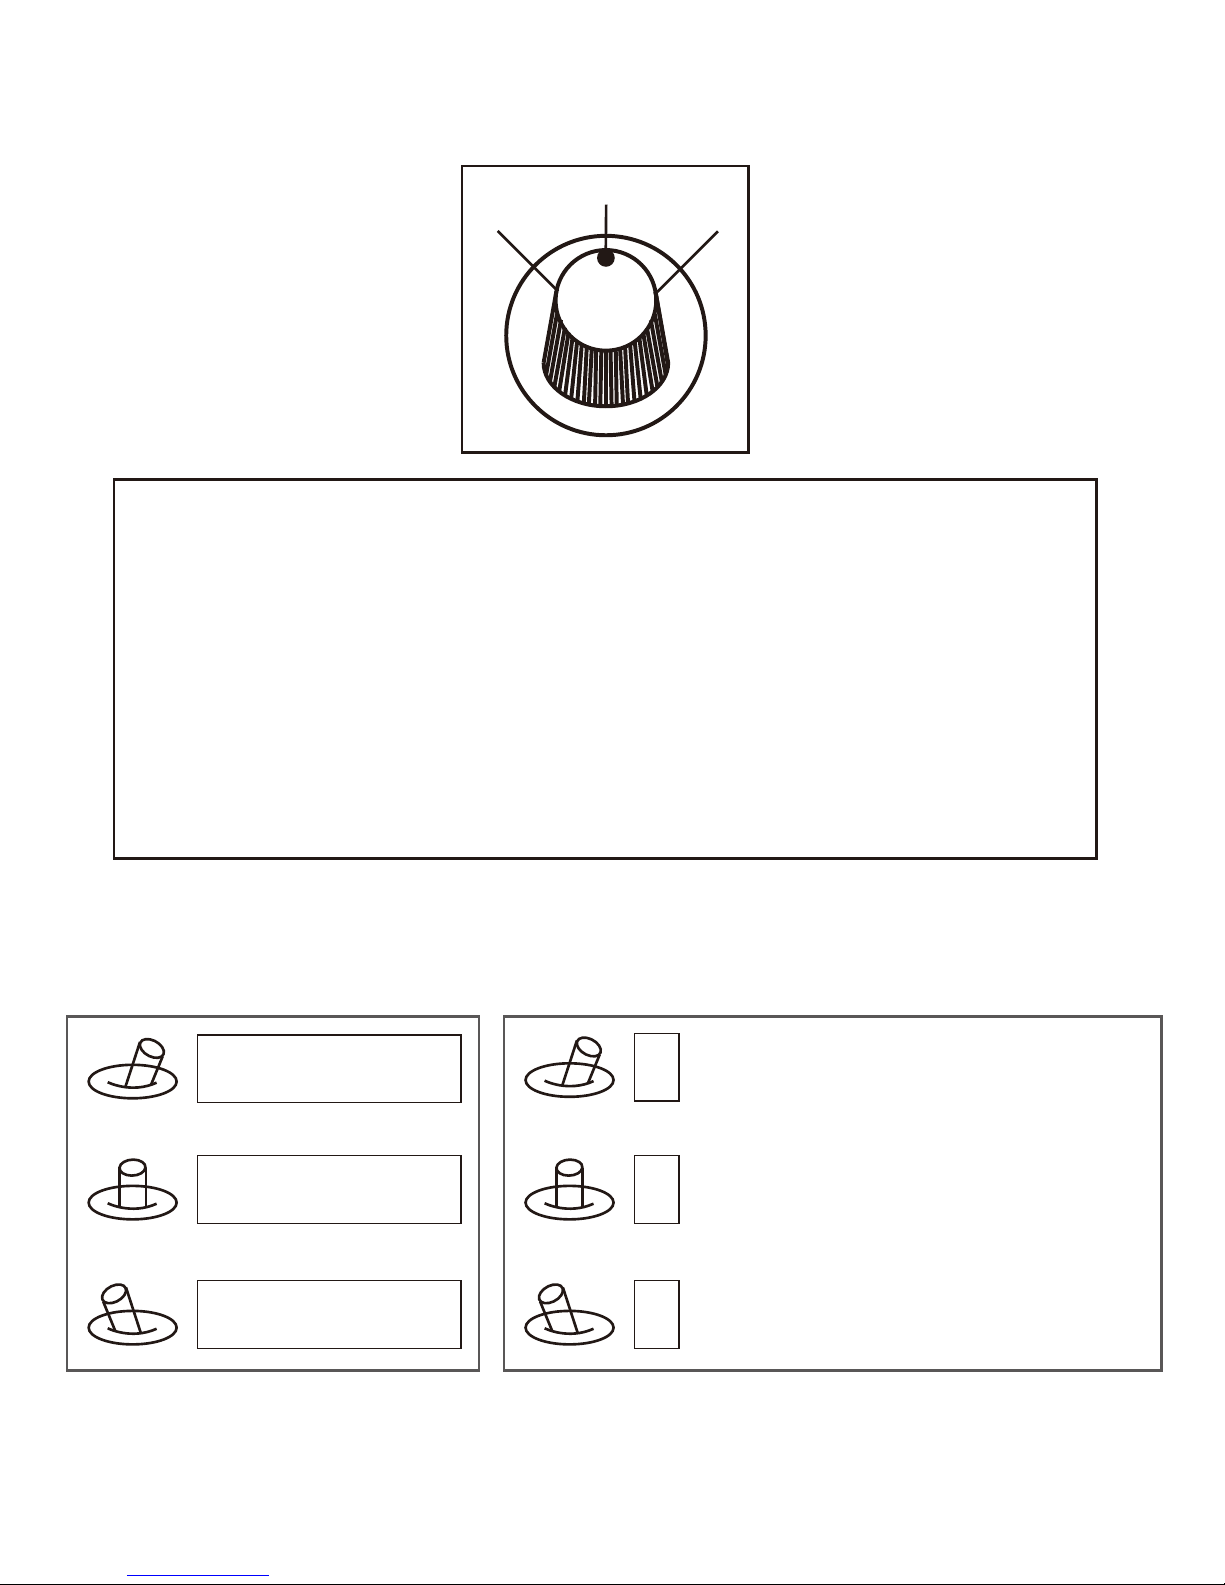
Mode: Change the speed / home position
1
2
3
Position 1: Lowest speed for pitch and yaw.
Position 2: Middle speed for pitch and yaw.
Position 3: Highest speed for pitch and yaw. The speed is continuously quickly
from 1 to 3.
One click: Home position.
Two click: Look down.
Three click: Yaw not followed by frame.
Four click: Yaw followed by frame.
Five click: Restore the factory settings.
(Click = from 2 to 3 and back to 2 quickly)
1. Zoom tele
2. Stop zoom
3. Zoom wide
ZOOM: Zoom the camera
Focus: Focus the camera
1
2
3
Switch 2 to 1: IR color white hot,
black hot, pseudo color
Switch 2 to 3: Picture in Picture.
EO+IR , IR+EO, EO only, IR only.
-8-
Page 10
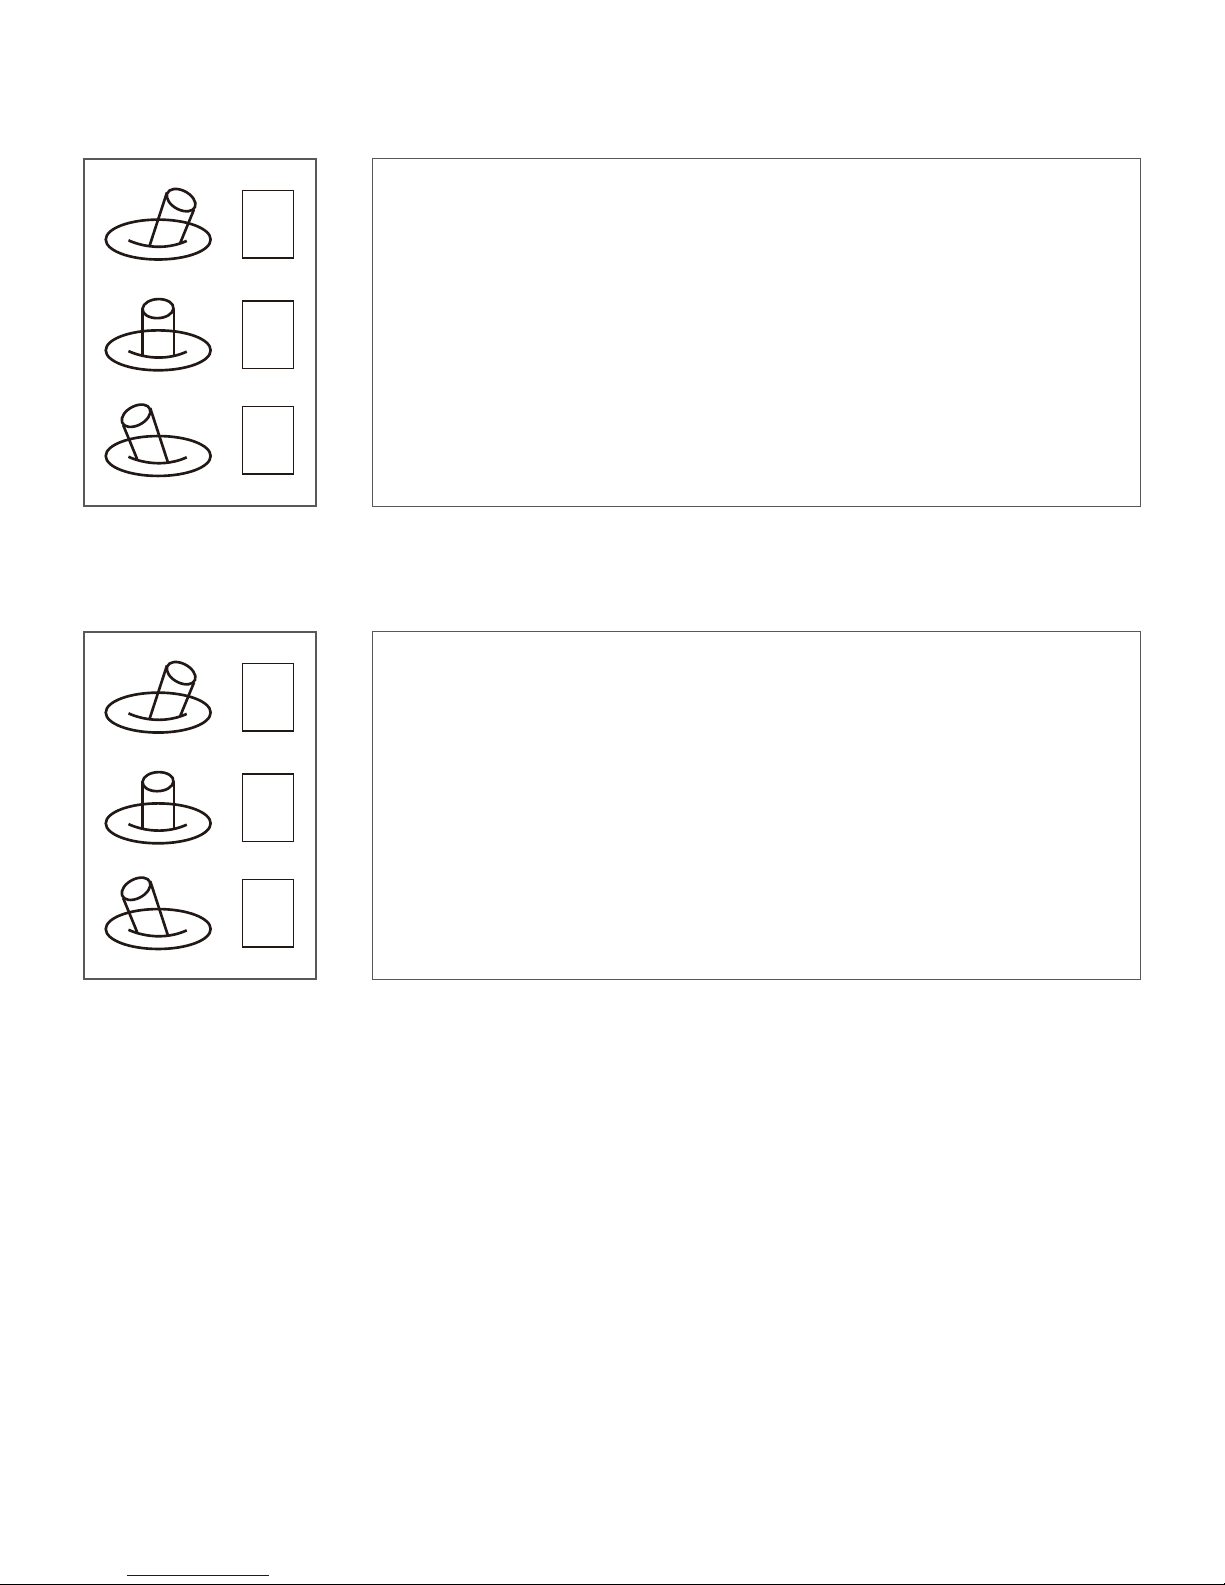
Pic /Rec picture / Start record, stop record
1
2
3
Switch 2 to 1:
Start record / stop record. start record,
the OSD display rec hh:mm:ss ; stop record, the OSD display STBY.
Switch 2 to 3: Take a picture.
OSD display’ REC IMG’ a second.
Multi: Tracking control
1
2
3
AV: NO AV output this model.
Position 1 exit the tracking
Switch 1 to 2: Display the cross cursor. Adjust the object to the
cross cursor.
Switch 2 to 3: Start tracking. Change the object during tracking.
Switch 3 to 2: Display the cross cursor, use Pitch/Yaw to adjust the
cross cursor.
Switch 2 to 3: Start tracking.
-9-
Page 11
-10-
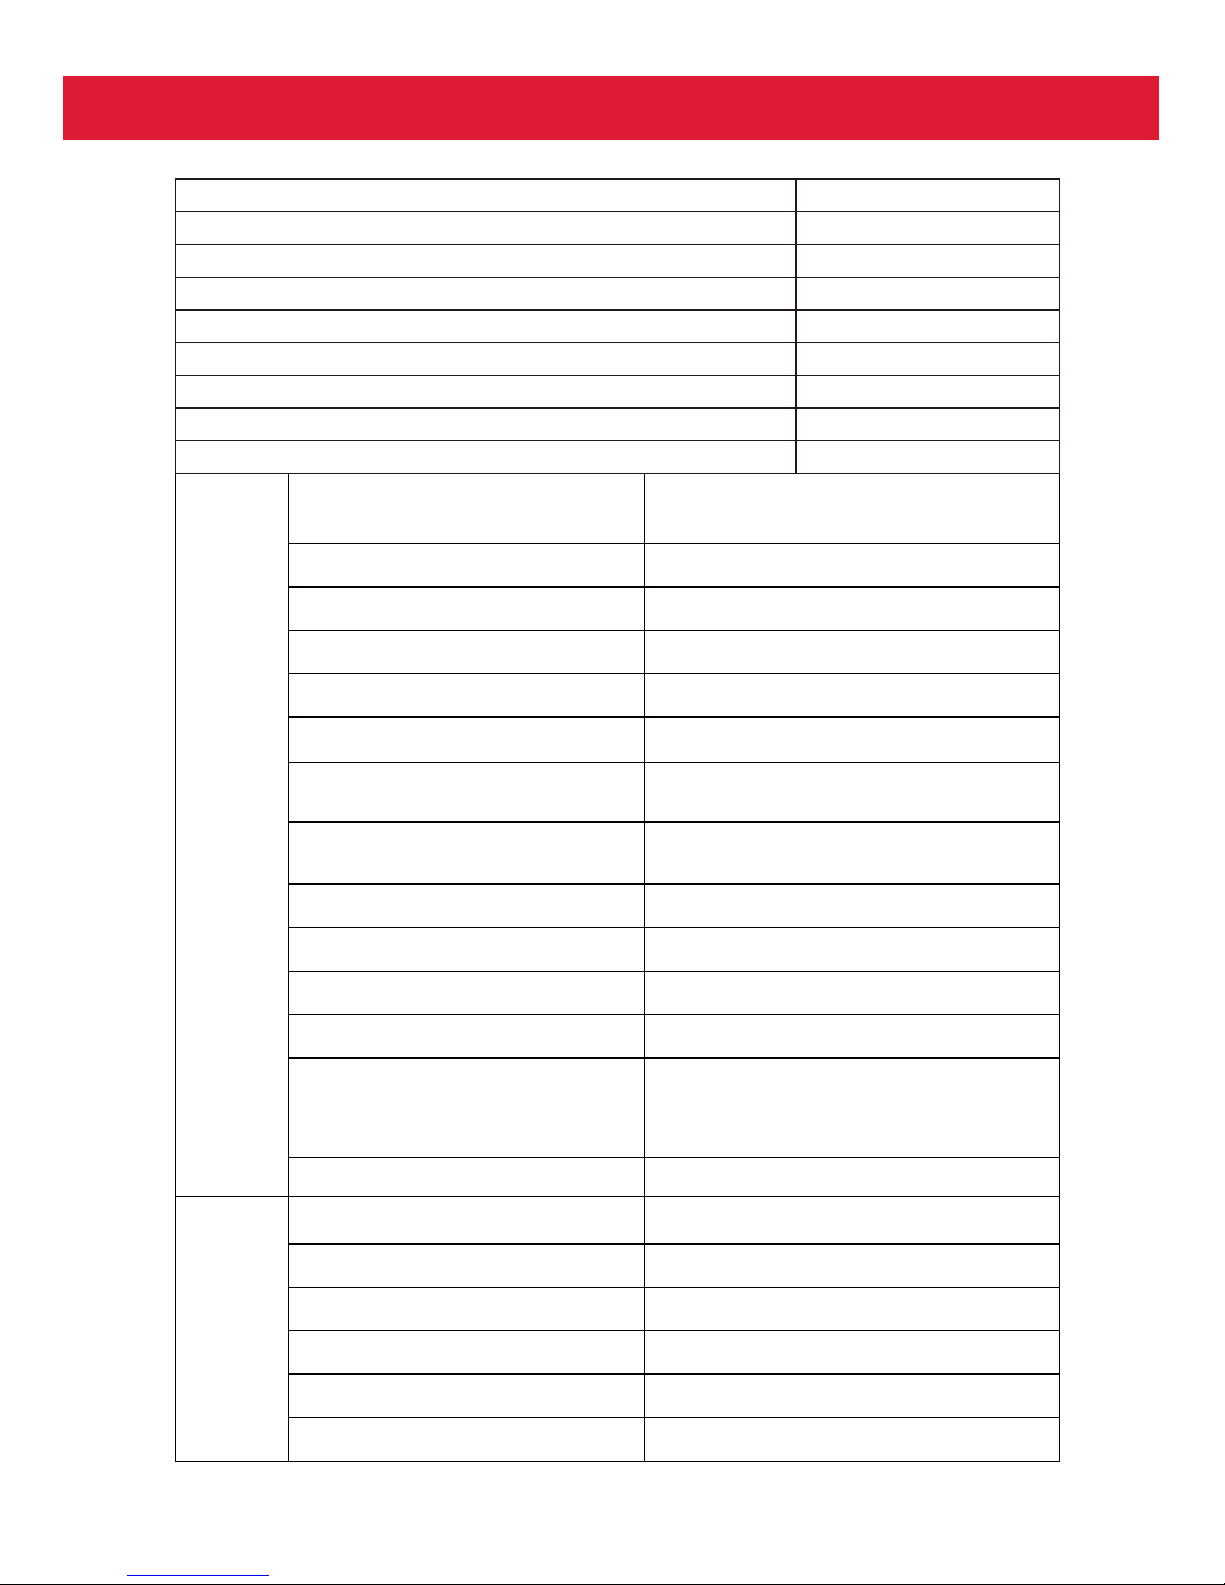
640 25mm Thermal Imager Parameter
32°
24°
39.4°
Vertical FOV
Horizont al FOV
Diagonal FO V
Detective D istance M an:1.8 x0 .5m( )
Reco gnize D istance M an 1.8x0 .5 m( : )
Verified D istance M an 1.8 x0 .5m ( : )
Detective D istance Car 4.2 x1 .8m( : )
Reco gnize D istance Car 4.2 x1 .8m( : )
Verified D istance Car 4 .2 x1.8m( : )
559meters
140meters
70meters
1714meters
428 meters
214 meters
Thermal
Imager
Spec
Working mode
Detector pixel
Pixel size
Focusing method
Emissivity correction
Image
enhancement
Color palette
Auto Non-uniform correction
Digital zoom
Sync correct time
Temperature type
Temperature warning
Update rate of deviation pixel
Output delay of deviation pixel
Minimum object size
Maximum object size
Tracking speed
Object memory time
Uncooled long wave (8μm~14μm)
thermal imager
640*480
17μm
Athermal prime lens
0.01~1
≤50mK (@25℃)
≤650mK
(@characteristic frequency)
Auto adjust image brightness
and contrast ratio
Black, white, pseudo color
25Hz
Yes (no shutter)
1x, 3x
Yes
Temperature bar ( psudo color
display) max temp, min temp,
FOV center temp
-20℃~120℃
<3ms
16*16 pixel
128*128 pixel
±32 pixel/frame
100 frames (4s)
Thermal
Object
Tracking
NETD
MRTD
Page 12
-11-
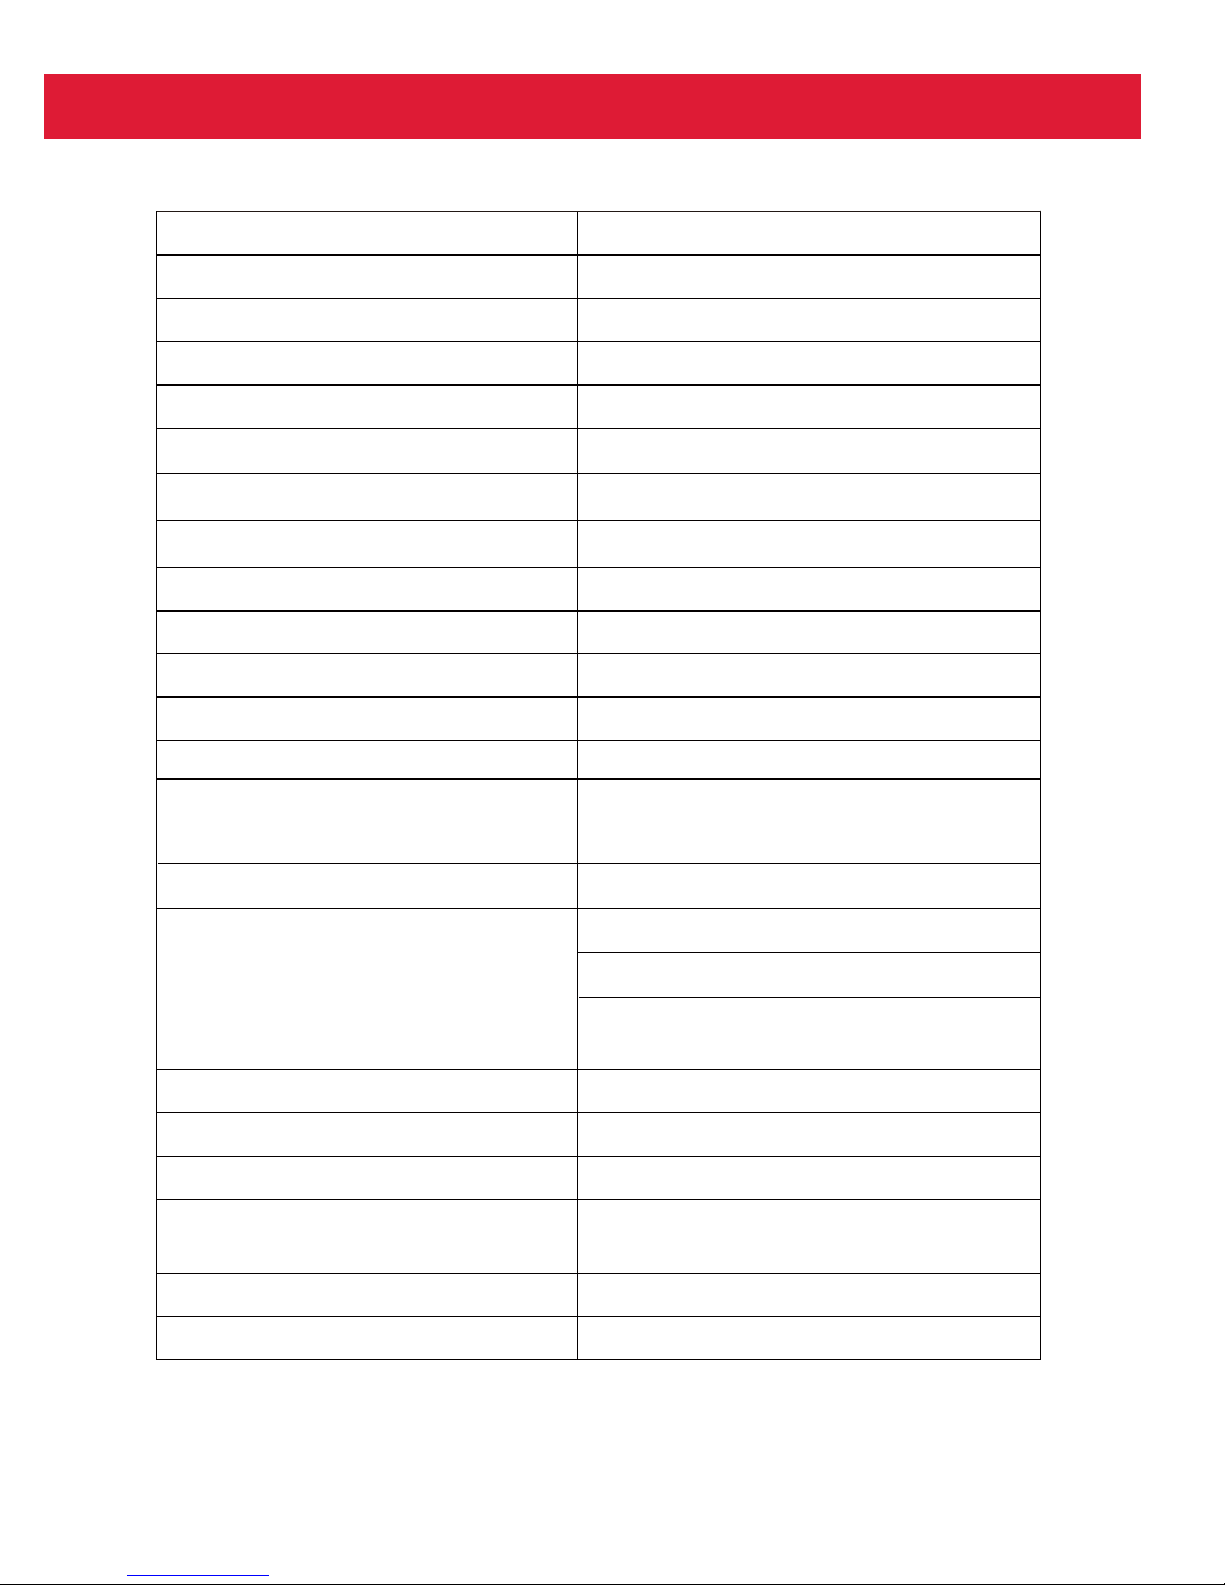
10x Visible Light Camera Specifications
Imager Sensor
Picture quality
Effective pixel
Video output
Min illumination
Shutter speed
Sync system
Exposure compensation
Backlight compensation
Gamma correction
Aperture control
White balance
Ae
Lens (wide end~tele end )
Horizontal viewing angle
Zoom mode
Zoom movement time
Focusing on the system
1/3 type progressive scanning CMOS
Full HD 1080 (1920*1080)
4.08MP
1080p/60, 1080p/50, 1080p/30,1080p/25
0.5 lx (1/30s, F1.8, 50%)
100 lx ~100,000 lx
Auto / Manual
1/1s to 1/10,000s
Internal
optical zoom10.5x
-12dB ~+ 12dB
ON / OF
standard
16 steps
ATW1 (Narrow), ATW2 (Wide),
single touch, manual (B, R)
Automatic, manual, priority mode
(shutter/aperture)
62°(wide end) ~ 6.5°(tele end)
Standard / Variable / Direct
1.5s
automatic, manual, single-touch,
autofocus sensitivity
Illumination range
Gain
Min object distance
Horizontal resolution
10mm(wide end) to 800mm(tele end)
Above center 800TV line
F=3.2~33.6mm
F1.8~3.4
 Loading...