

Page 1
QUICK START GUIDE
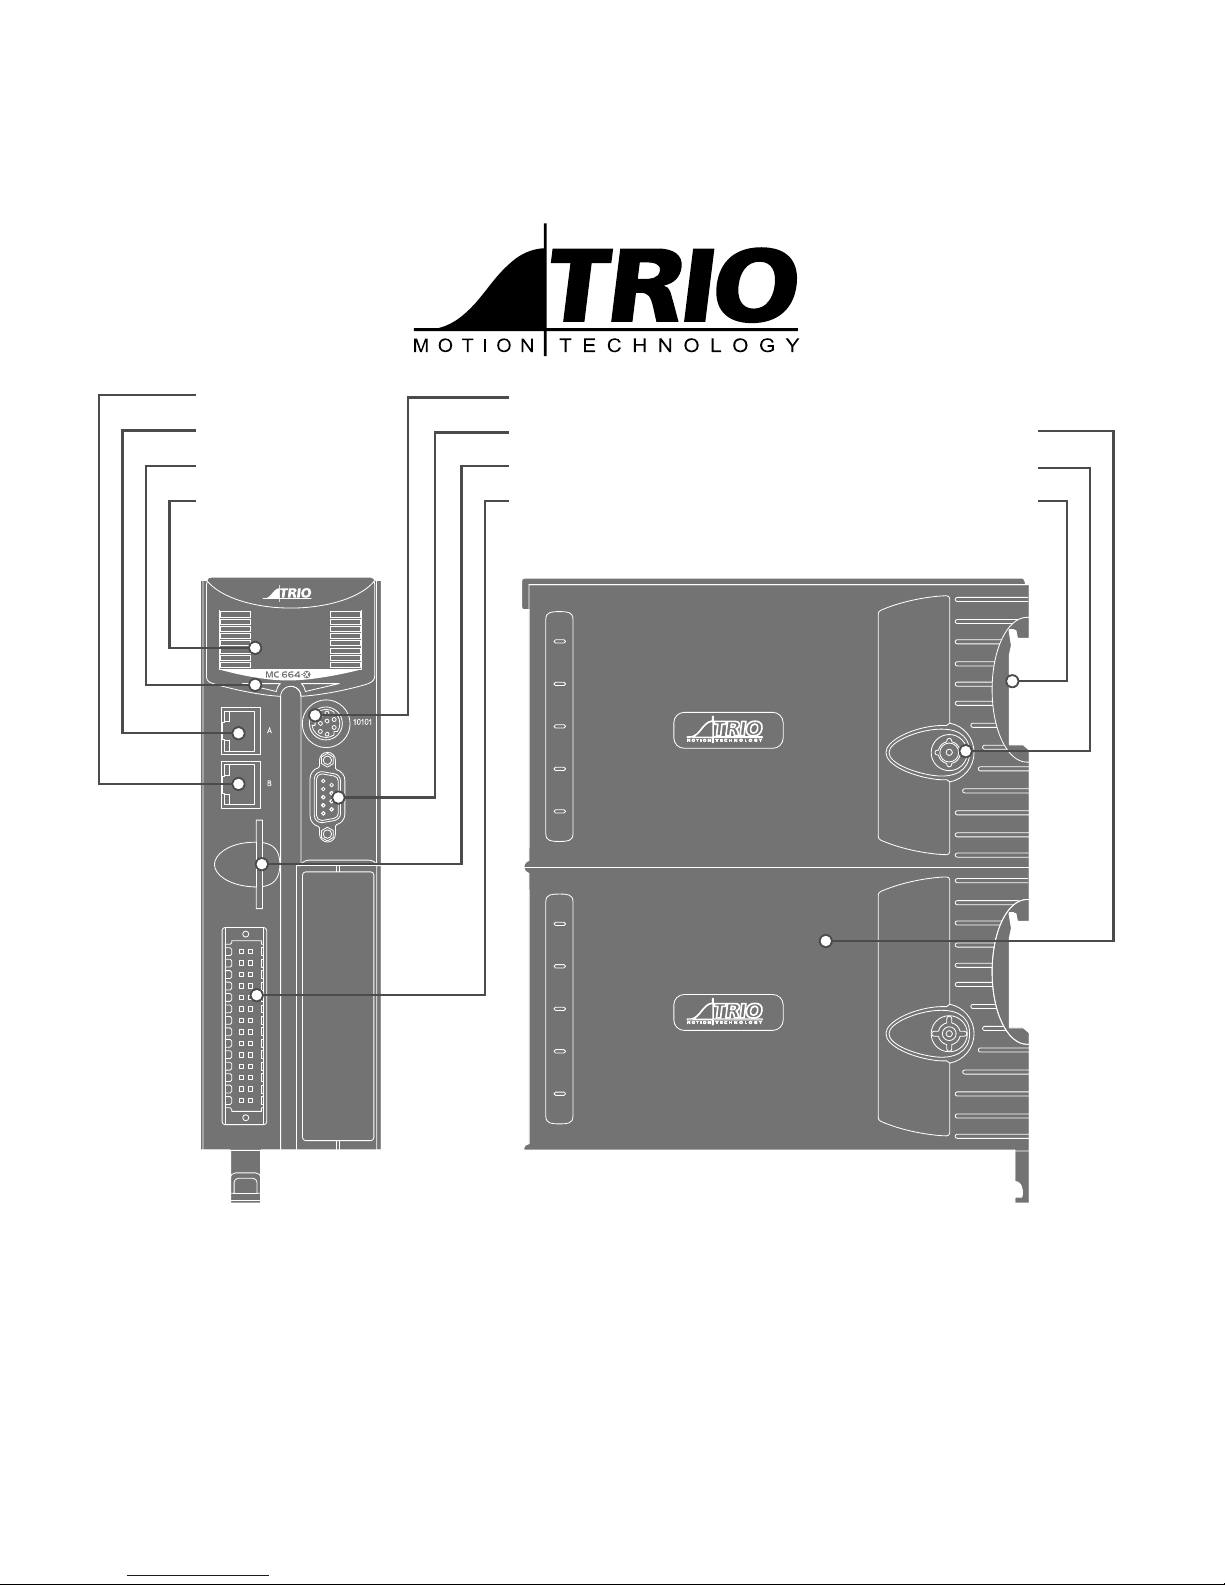
MC664 | MC664-X
P861 | P862
BACKLIT DISPLAY
ETHERCAT PORT
SD CARD SLOT
FLEXIBLE AXIS PORT
RS232 / RS485 PORT
ETHERNET PORT
STATUS LED’S
POWER - I/O - WDOG
COMMON EARTH
EXPANSION MODULE
PANEL OR DIN MOUNT
Page 2
2
SAFETY WARNING
During the installation or use of control systems, users of Trio products must ensure that there is no possibility of injury to any
person or damage to machinery.
Control systems, especially during installation, can malfunction or behave unexpectedly. Bearing this in mind, users must
ensure that even in the event of a malfunction or unexpected behaviour, the safety of an operator or programmer is never
compromised.
MC664(X) FEATURE SUMMARY
MC664 MC66 4 -X
Processor ARM A9 Single Core ARM A9 Quad Core
Servo update rate 125 to 4000 usecs 50 to 4000 usecs
Maximum axes 64 128
Absolute encoder support Yes Yes
EtherCAT axes included (1) 0 2
EtherCAT registration (2) Inputs 0 to 7 Inputs 0 to 7
Firmware recovery mode Yes Yes
Non-volatile memory
VR store Flash Flash
Table (1st 196k) Flash Flash
Real time clock Super capacitor Super capacitor
(1) More axes can be enabled by purchasing software codes
(2) EtherCAT registration also available by Touch Probe
SOFTWARE
Trio recommend that you use the latest version of Motion Perfect 4 when using the MC664 (Minimum recommended version
MP v4.3.1).
Software can be downloaded from www.triomotion.com
Page 3
3
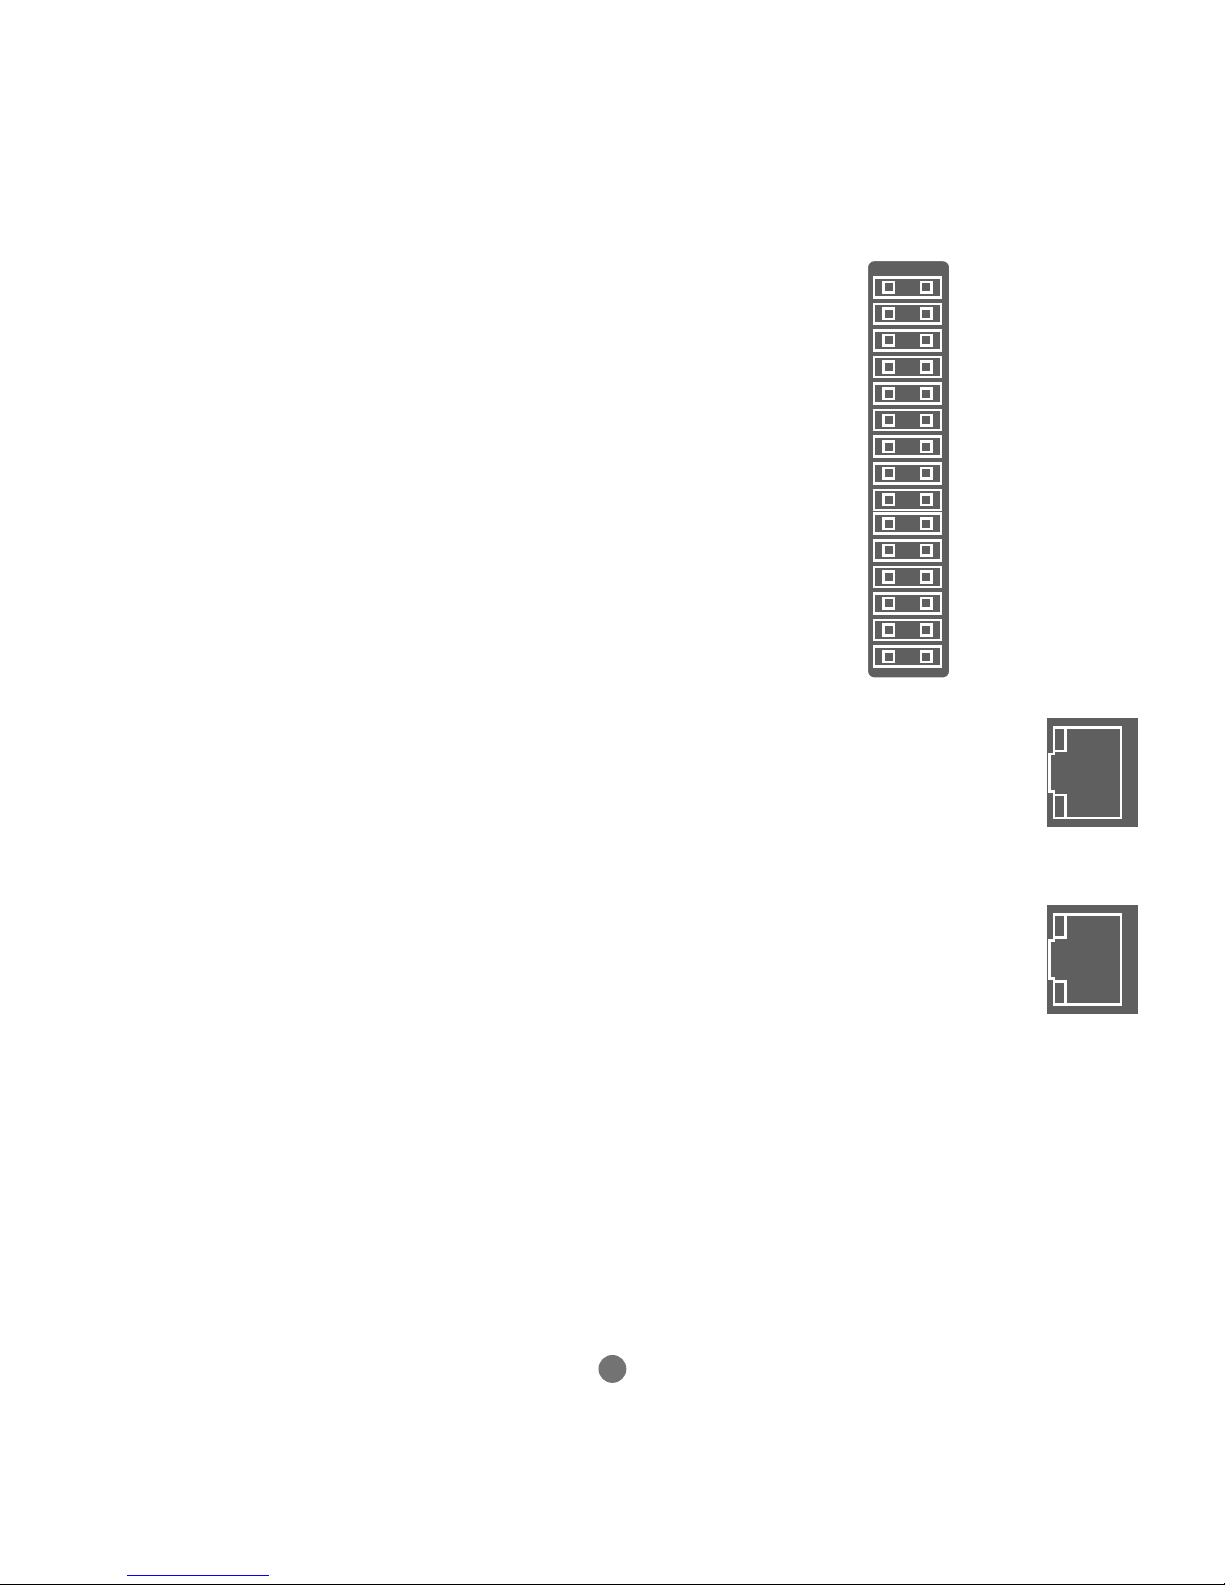
I/O CONNECTOR
The bottom 2 pins of the 30 way high density input connector are used to
provide the 24V dc power to the MC664. A 24V dc, Class 2 transformer or
power source must be provided.
The 2 pins above the 24V dc supply are to power the I/O 24 Volts.
THE MC664 IS GROUNDED VIA THE METAL CHASSIS. IT MUST BE
INSTALLED O
N A
N UNPAINTED METAL PLATE OR DIN RAIL WHI
CH IS
CONNECTE
D T
O E
ARTH.
THE MC464 I/O CONNECTOR DOES NOT FIT INTO THE MC664 /
MC664-
X MOTION COOR
DINATER.
RJ45 ETHERNET CONNECTOR (TOP)
A standard Ethernet connector is provided for use as the primary programming interface.
The Trio programming software, Motion Perfect 4 and above, must be installed on a Windows based PC that is
tted with an Ethernet connection. The IP address is displayed on the MC664 display for a few seconds after
power-up or when an Ethernet cable is plugged in.
RJ45 ETHERCAT CONNECTOR (BOTTOM)
EtherCAT master port for connection to Servo/Stepper drives and I/O devices via EtherCAT industry standard
protocols.
Recommended screened cable for EtherCAT; Cat5 SF/UTP.
0V AIN
AIN0
AIN1
WDOG+
WDOG-
I 0
I 1
I 2
I 3
I 4
I 5
I 6
I 7
0V I/O
0V SUPPLY
0V CA N /A I N
CAN LOW
CAN EARTH
CAN HIGH
24V CAN/AIN SUPPLY
I/O8
I/O9
I/O10
I/O 11
I/O12
I/O13
I/O14
I/O15
24V I/O SUPPLY
24V SUPPLY
Page 4
4
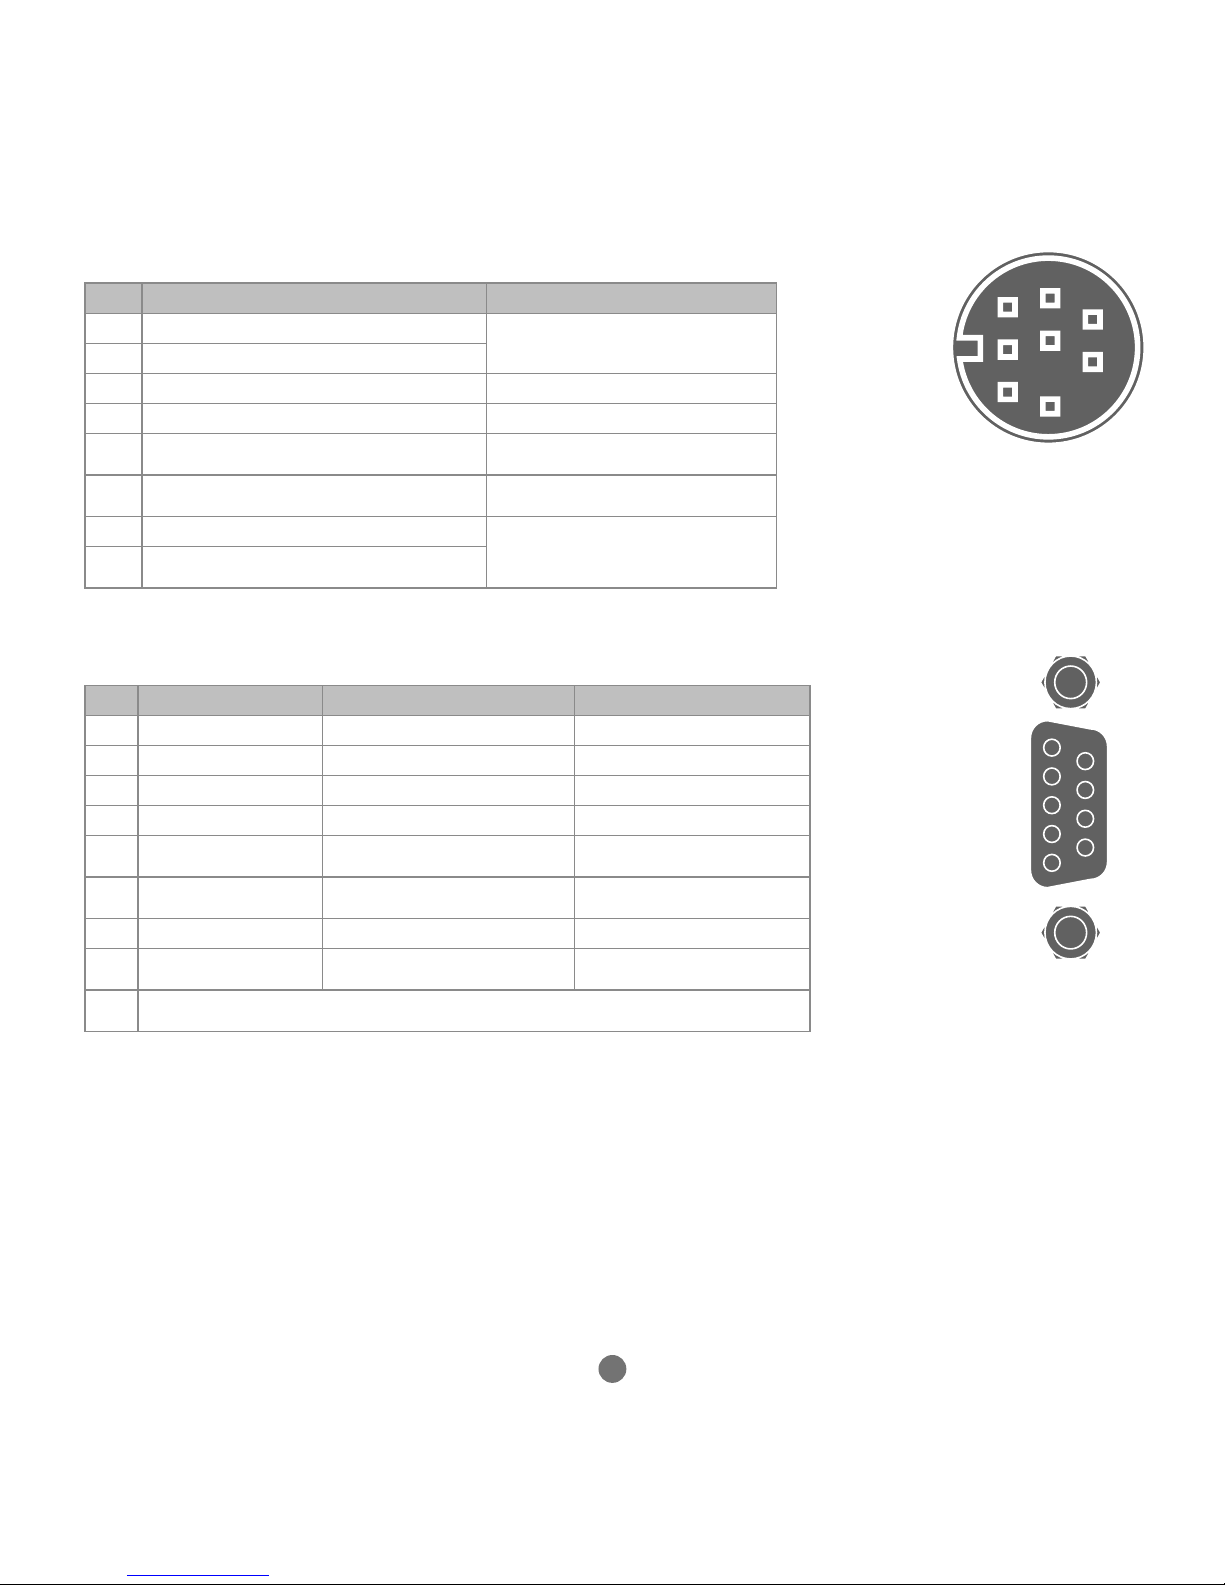
SERIAL CONNECTIONS (RS232) 8 WAY MINI-DIN
Pin Function Note
1 RS485 Data In A R x+
Serial Port #2
2 RS485 Data In B R x-
3 RS232 Transmit Serial Port #1
4 0V Serial
5 RS232 Receive Serial Port #1
6 Internal 5V
7 RS485 Data Out Z Tx-
Serial Port #2
8 RS485 Data Out Y Tx+
SYNC ENCODER CONNECTIONS (9 WAY D-TYPE)
Pin Encoder Absolute Pulse & Direction
1 Enc. A Clk + Step +
2 Enc. /A Clk - Step -
3 Enc. B N/C Direction +
4 Enc. /B N/C Direction -
5 0V Encoder 0V Enc. 0V Stepper
6 Enc. Z Data + Enable -
7 Enc. /Z Data - Enable +
8 5V* 5V 5V*
9 Registration Input (5V)
* 5V supply is limited to 150mA.
8
7
6
5
4
3
1
2
1
2
3
4
5
6
7
8
9
Page 5
5
LCD DISPLAY
The model number, IP address and subnet mask of the MC664 are shown on the LCD display for a few seconds after power-up.
The factory default IP address is 192.168.0.250. This can be changed using the ETHERNET or the IP _ ADDR ESS command via
Motion Perfect.
0
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
ENABLE
0
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
Display at start-up Display with WDOG on
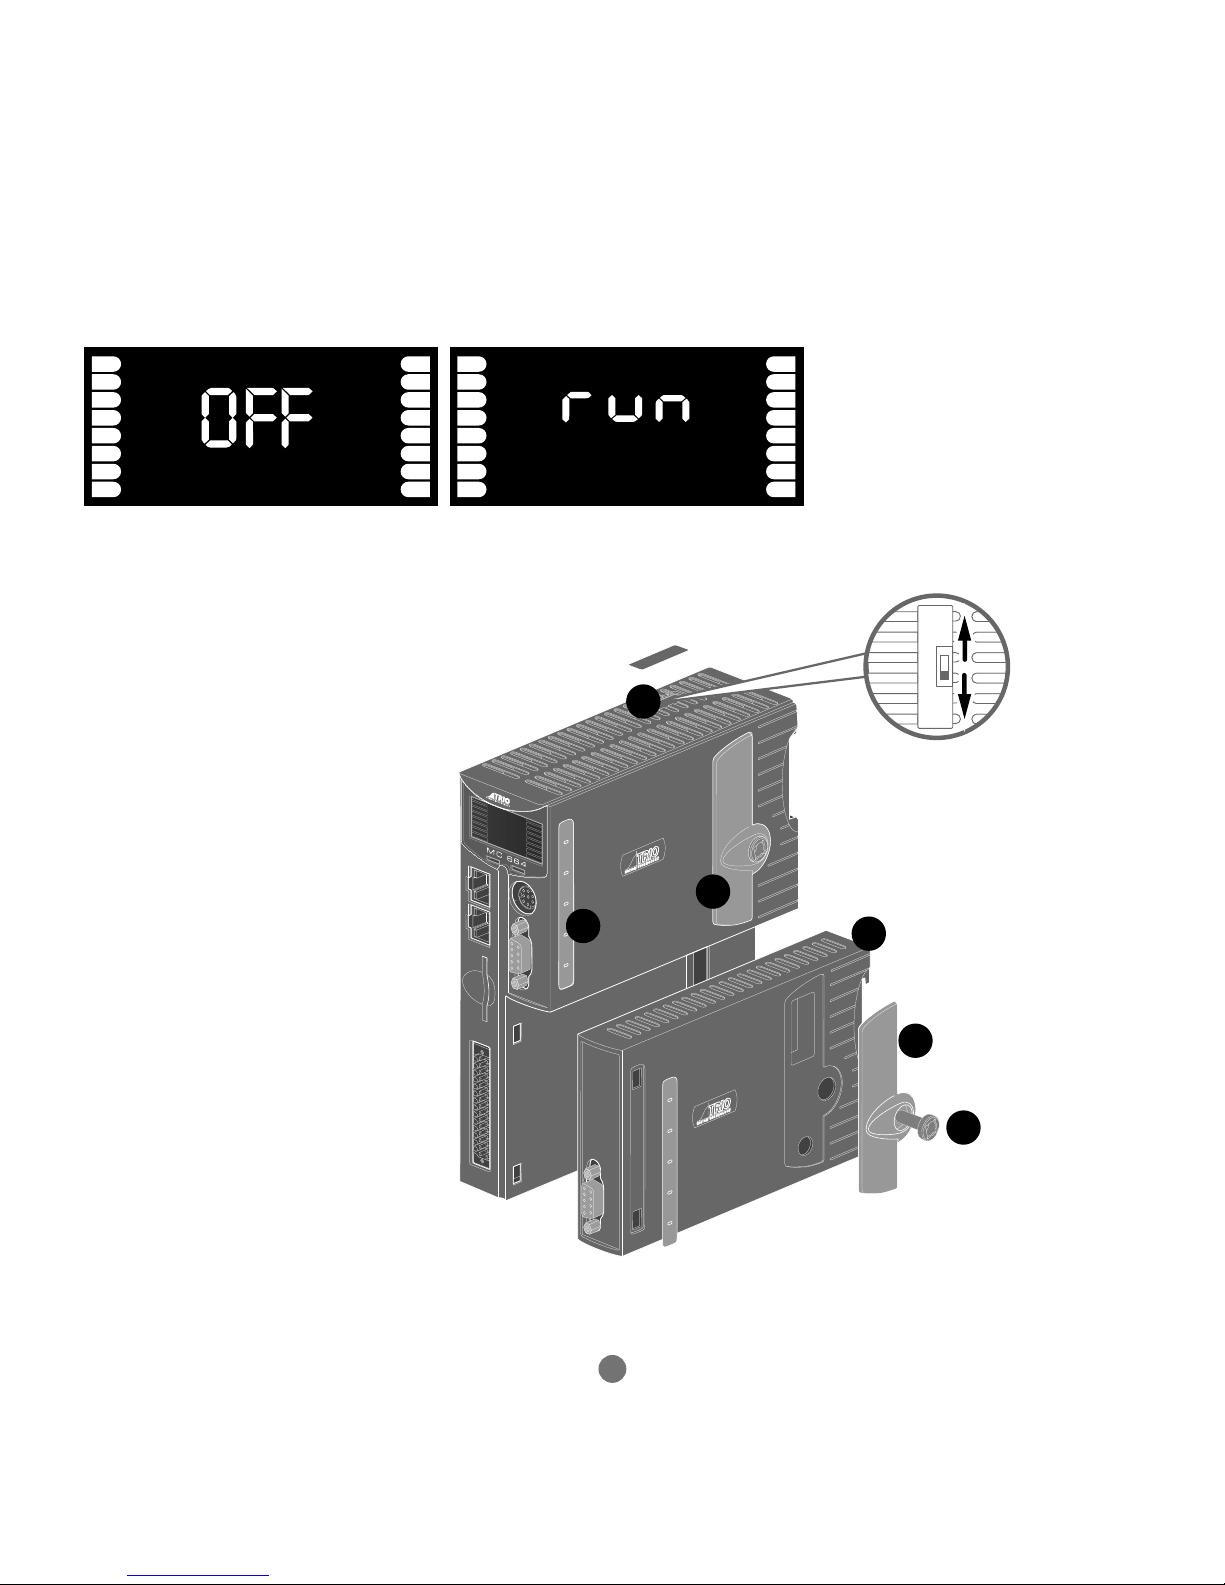
ADDING EXPANSION MODULES
Unscrew the lower retaining xing (A) using
the supplied tool or a coin.
Remove the covers from the module (B).
Swing the expansion module (C) out from the
rear and unclip from the front end.
Replacing the module is the reverse of the
procedure.
Remove covers (E) before tting full height
expansion modules.
To access the recovery mode switch, insert
screwdriver under the frontmost ventilation
slot (D). See the Hardware Manual for
details of recovery mode operation.
B
Recovery
Normal
C
D
A
E
E
Page 6
6
ERROR DISPLAY CODES
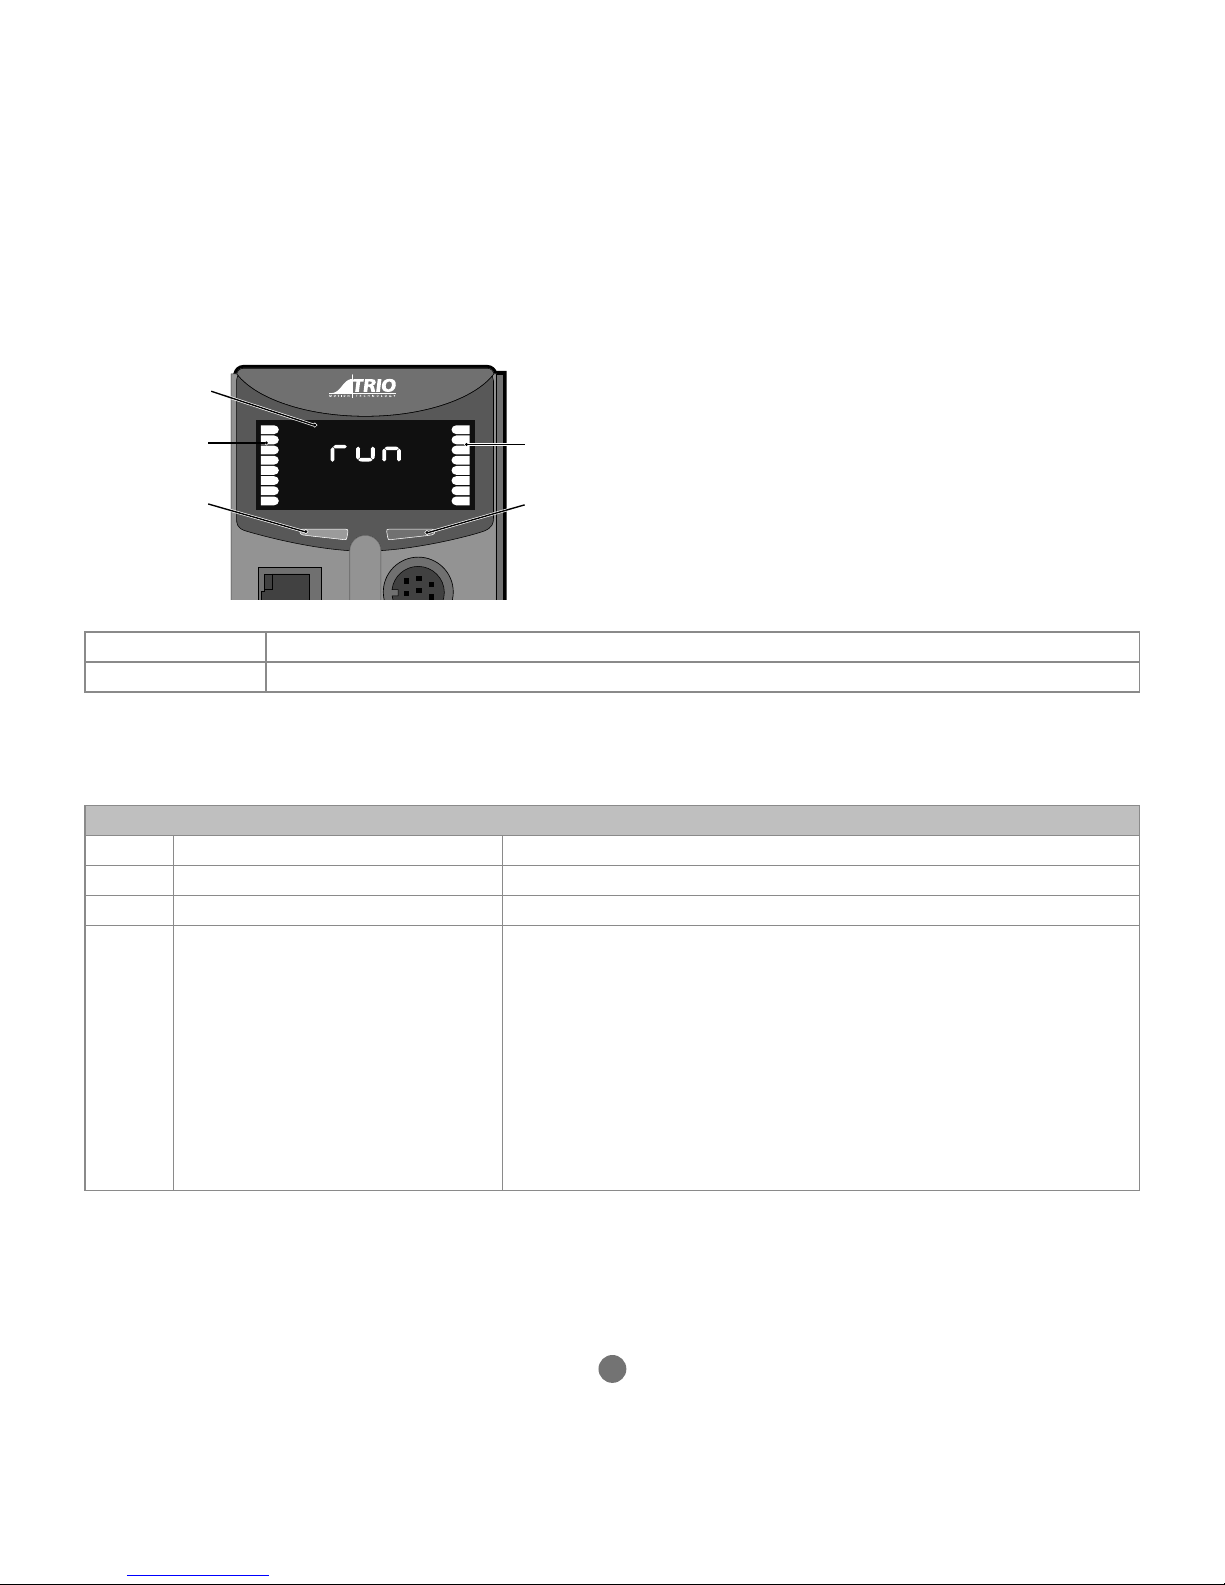
The information display area shows the IP address and subnet mask during power-up and whenever an Ethernet cable is rst
connected to the MC664. During operation, this display shows run, O or Err to indicate the MC664 status. Below the main
status display are the ERROR and ENABLE indicators.
101011
0
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
ENABLE
Information Display
Input Status
I/O Status
Ok
Status
ERROR An error has occurred (see Error Display Codes table below for details).
ENABLE When illuminated, WDOG is ON.
A bank of 8 indicators at the left side shows the Digital Input States and a similar bank on the right shows the state of I/O8 to I/
O15. The I/O displayed can be altered using the DISPL AY command.
Two LED’s are provided to show the processor (OK) and system status.
Error Display Codes
Unn Unit error on slot nn ie: EtherCAT failed to start
Ann Axis error on axis aa ie: following error exceeds limit
Caa Conguration error on unit aa ie: too many axes
Exx System error
E00 - RAM error 8bit BB - RAM (VR)
E01 - RAM error 16 bit BB - RAM (TABLE)
E04 - VR/TABLE corrupt entry
E05 – Invalid MC_CONFIG le
E06 – Started in SAFE mode (system timeout)
E07 - FPGA Error
E08 - Flash memory error
E09 - Processor Exception
E10 - RFID chip access failed
Page 7
7
MODULE ASSEMBLY
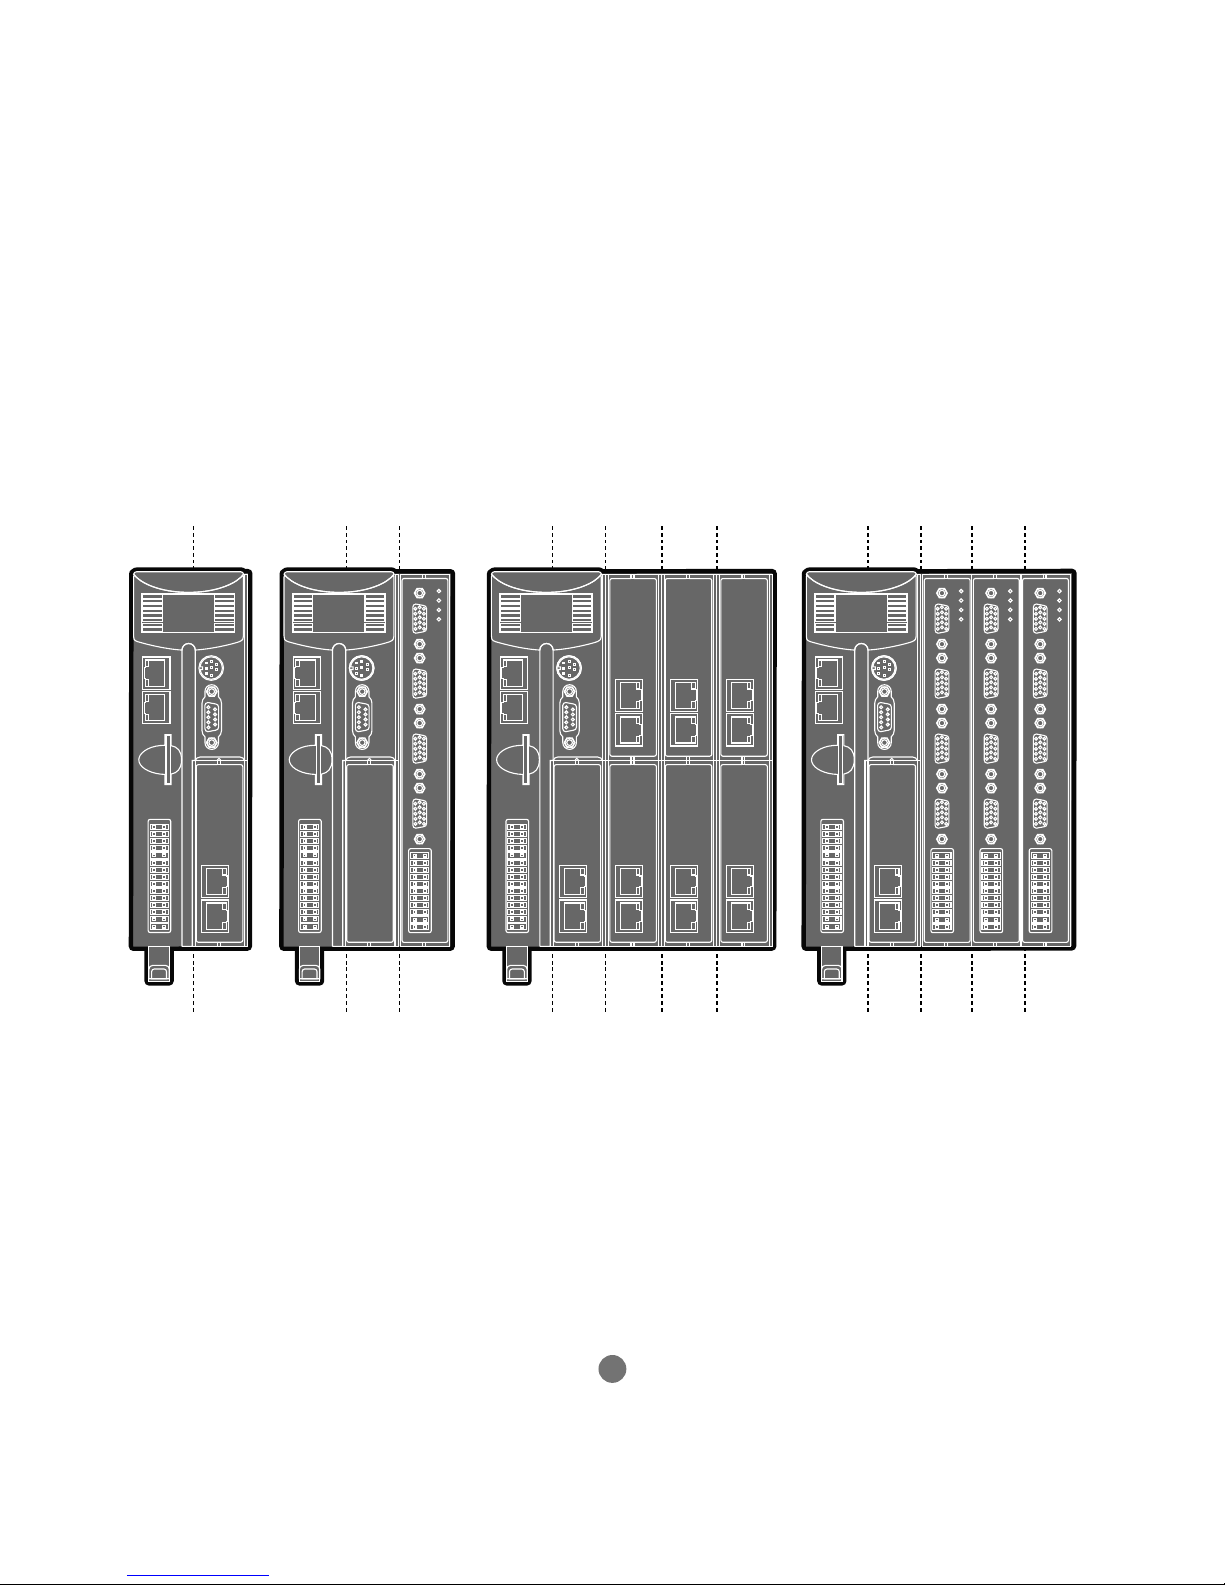
A maximum of 7 half height modules or 3 full height modules may be tted to the MC664. A system may be made using any
combination of half and full height modules providing that the full height modules are the last to be attached.
MODULE SLOT NUMBERS
SLOT Numbers are allocated by the system software in order, left to right, starting with the lower bus. Lower modules are
allocated slots 0 to m, then the upper modules become slots m+1 to n. Finally the EtherCAT Port and the Sync Encoder Port are
allocated slots n+1 and n+2.
2 1 1 SLOT
SLOT 0
2 0
*
7 4 5 6
0 1 2 3
4 5 1 2 3
0
* EtherCAT Port is disabled.
Page 8
8
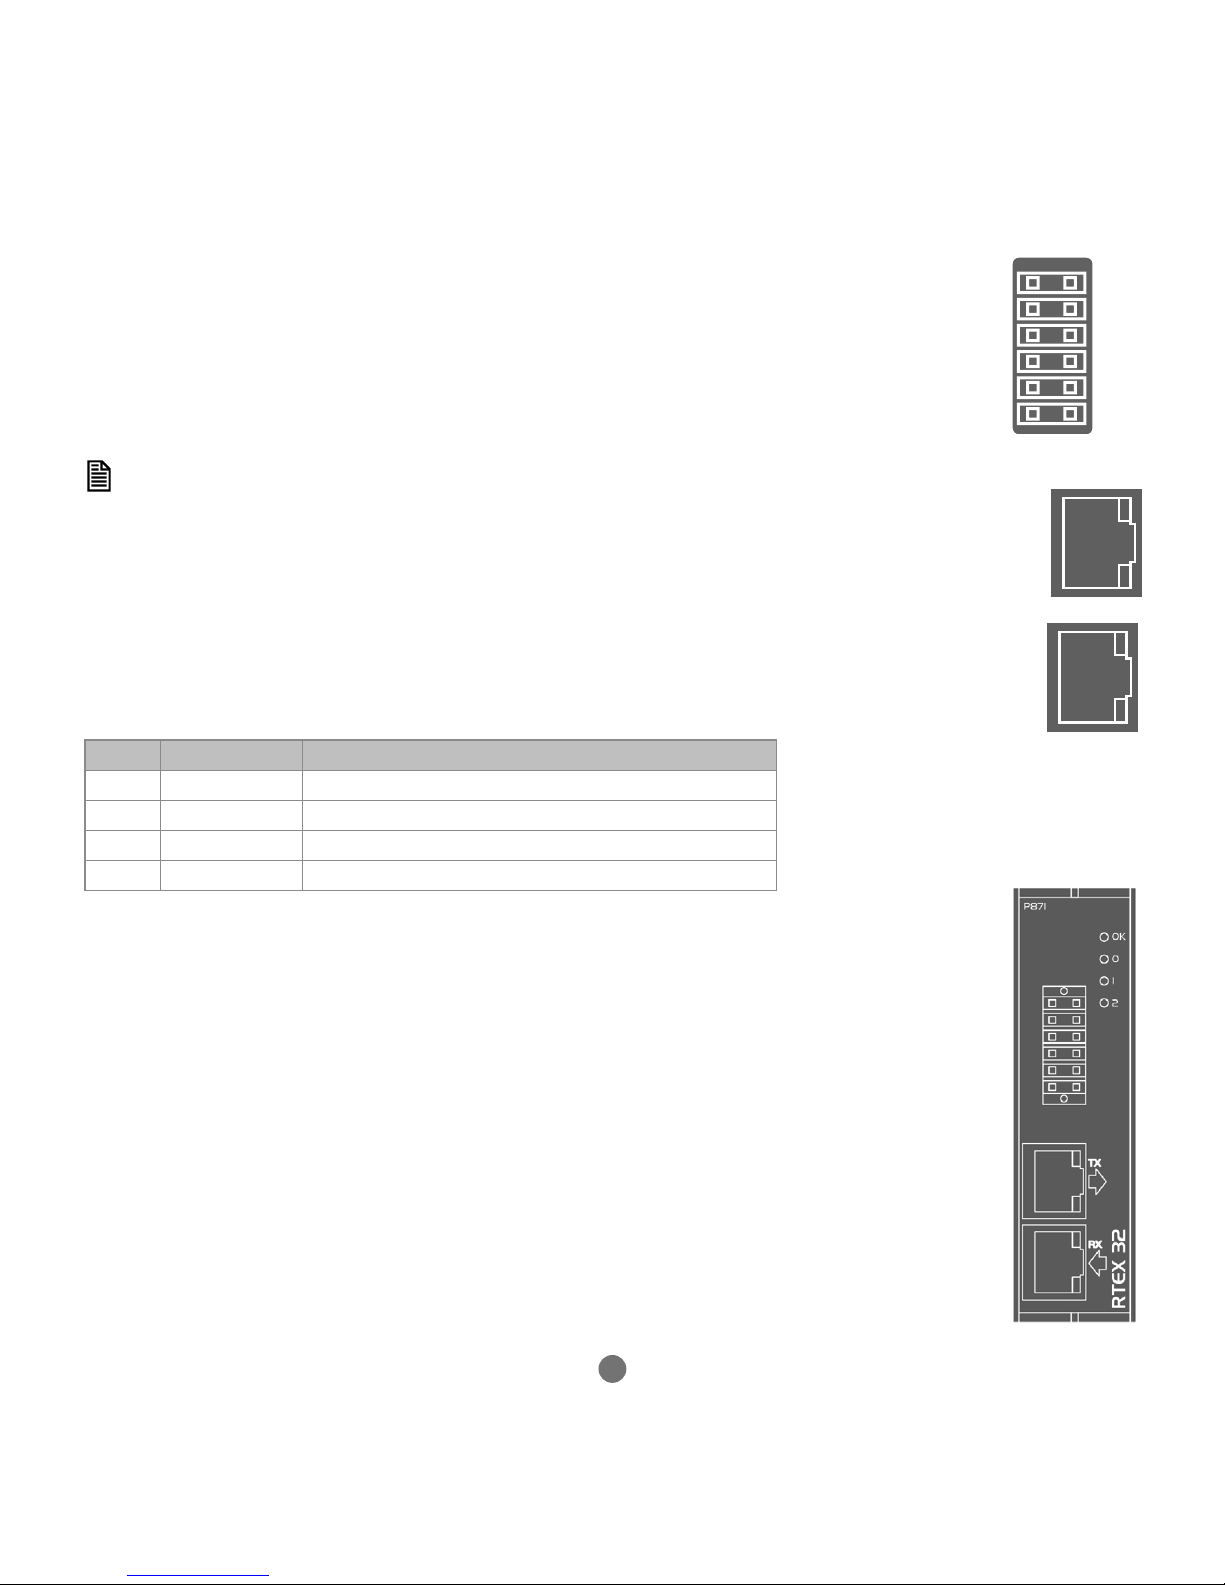
EXPANSION MODULE P871 - PANASONIC INTERFACE
REGISTRATION CONNECTOR
R0 - R7 registration inputs (24V).
R0V:
r
egistration common 0V return.
Registration inputs can be allocated to any axis by software.
Al
so available to software as general purpose inputs.
This pin out applies to module serial numbers P871-00011 and higher.
RJ45 CONNECTOR (TX)
100Mbps Panasonic “Realtime Express” transmit – connect to receive of rst drive.
RJ45 CONNECTOR (RX)
100Mbps Panasonic “Realtime Express” receive – connect to transmit of last drive.
LED FUNCTIONS
LED LED Colour LED Function
ok Green ON=Module Initialised Okay
0 Red ON=Module Error
1 Yello w Status 1
2 Yello w Status 2
R0
R1
R2
R3
R0V
R0V
R4
R5
R6
R7
R0V
R0V
Page 9
9
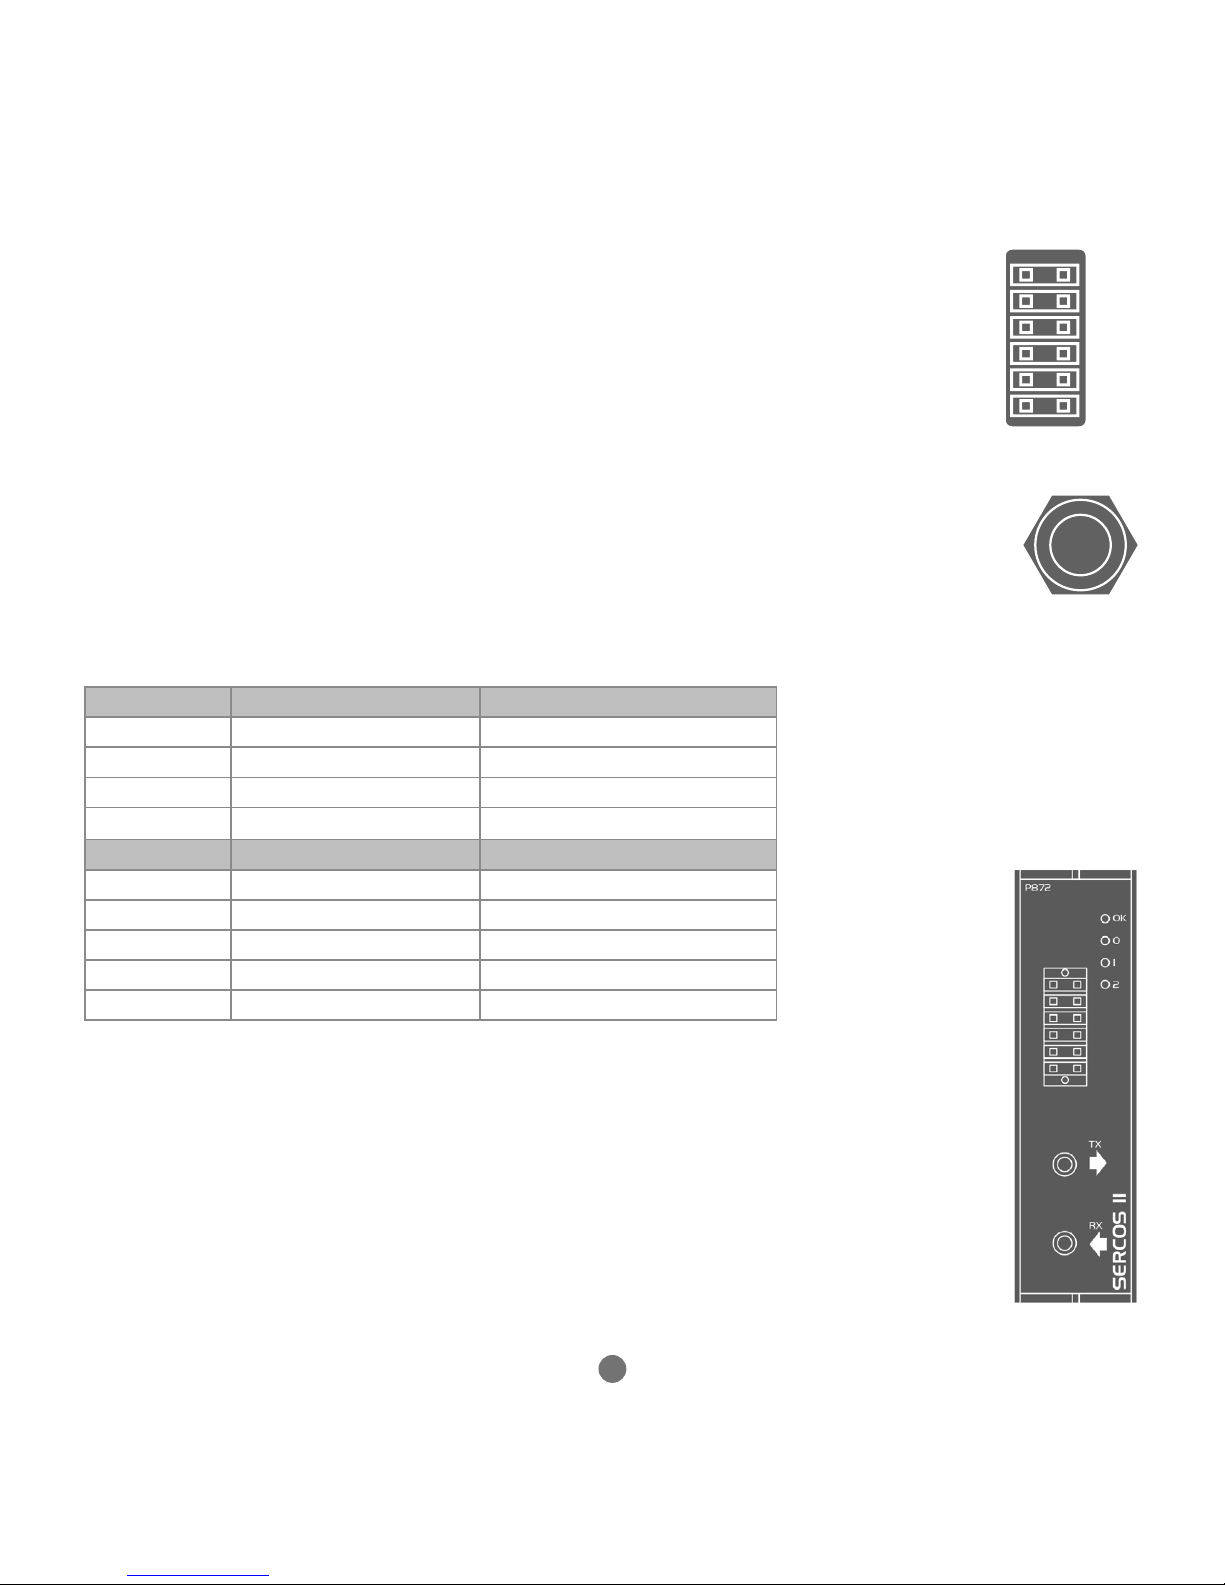
EXPANSION MODULE P872 - SERCOS INTERFACE
REGISTRATION CONNECTOR
R0 - R7: registration inputs (24V).
R0V:
r
egistration common 0V return.
CONNECTOR (TX)
sercos bre-optic transmit. (9mm FSM A)
CONNECTOR (RX)
sercos bre-optic receive. (9mm FSMA)
LED FUNCTIONS
LED LED Colour LED Function
ok Green ON=Module Initialised Okay
0 Red ON=Ring Open / Distorted
1 Yello w sercos Phase
2 Yello w sercos Phase
SERCOS PHASE LED 1 LED 2
0 OFF FLASH
1 OFF ON
2 FLASH OFF
3 ON OFF
4 ON ON
R0
R1
R2
R3
R0V
R0V
R4
R5
R6
R7
R0V
R0V
Page 10
10
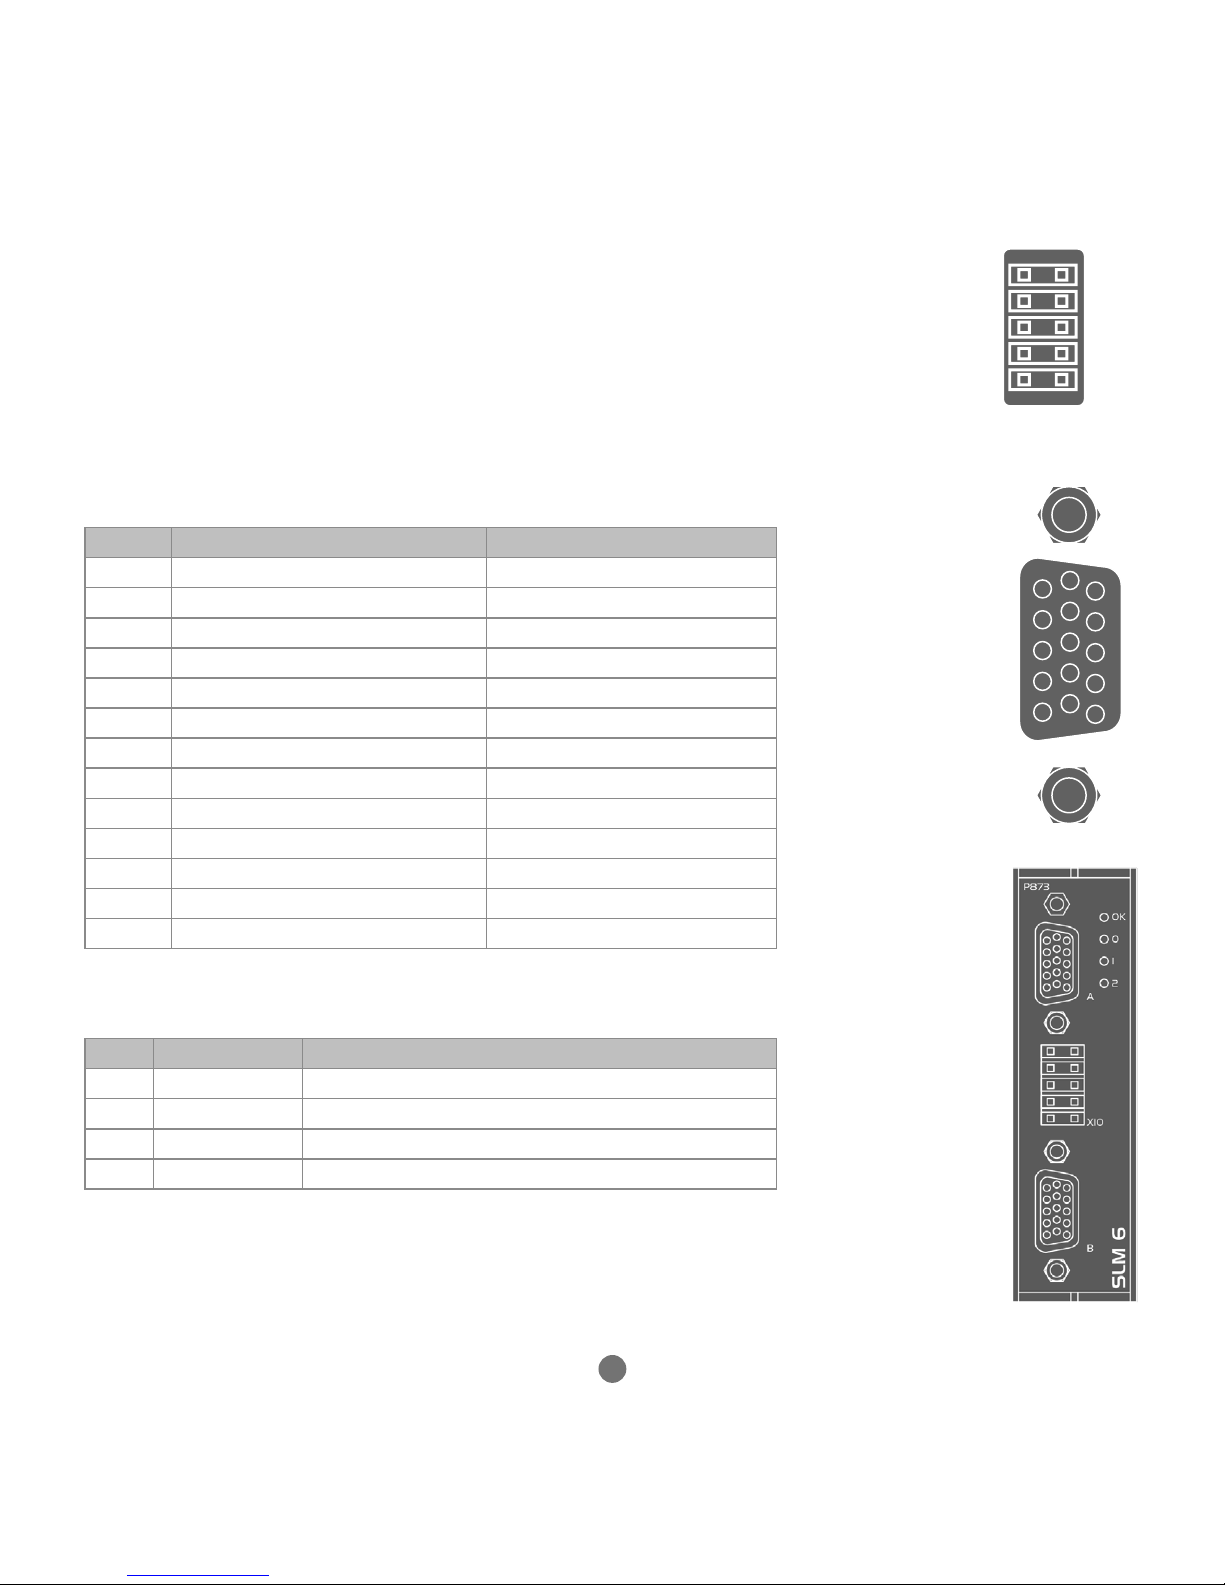
EXPANSION MODULE P873 - SLM INTERFACE
REGISTRATION CONNECTOR
R0 - R5: registration inputs (24V).
0VR:
co
mmon 0V return.
0V PWR: Power input for SLM system.
24V:
P
ower input for SLM system.
SLM CONNECTOR (15 WAY D-TYPE)
Pin Upper D-Type Lower D -Typ e
1 Com Axis 0 Com Axis 3
2 /Com Axis 0. /Com Axis 3
3 Hardware Enable Hardware Enable
4 0V Output 0V Output
5 24V Output 24V Output
6 Com Axis 1 Com Axis 4
7 /Com Axis 1 /Com Axis 4
8, 9, 10 No Connection No Connection
11 24V Output 24V Output
12 0V Output 0V Output
13 Com Axis 2 Com Axis 5
14 /Com Axis 2 /Com Axis 5
15 Earth / Shield Earth / Shield
LED FUNCTIONS
LED LED Colour LED Function
ok Green ON=Module Initialised Okay
0 Red ON=Module Error
1 Yellow Status 1
2 Yellow Status 2
R0
R1
R2
R0V
0V PWR
R3
R4
R5
R0V
24V
6
10
1
5
11
15
Page 11
11
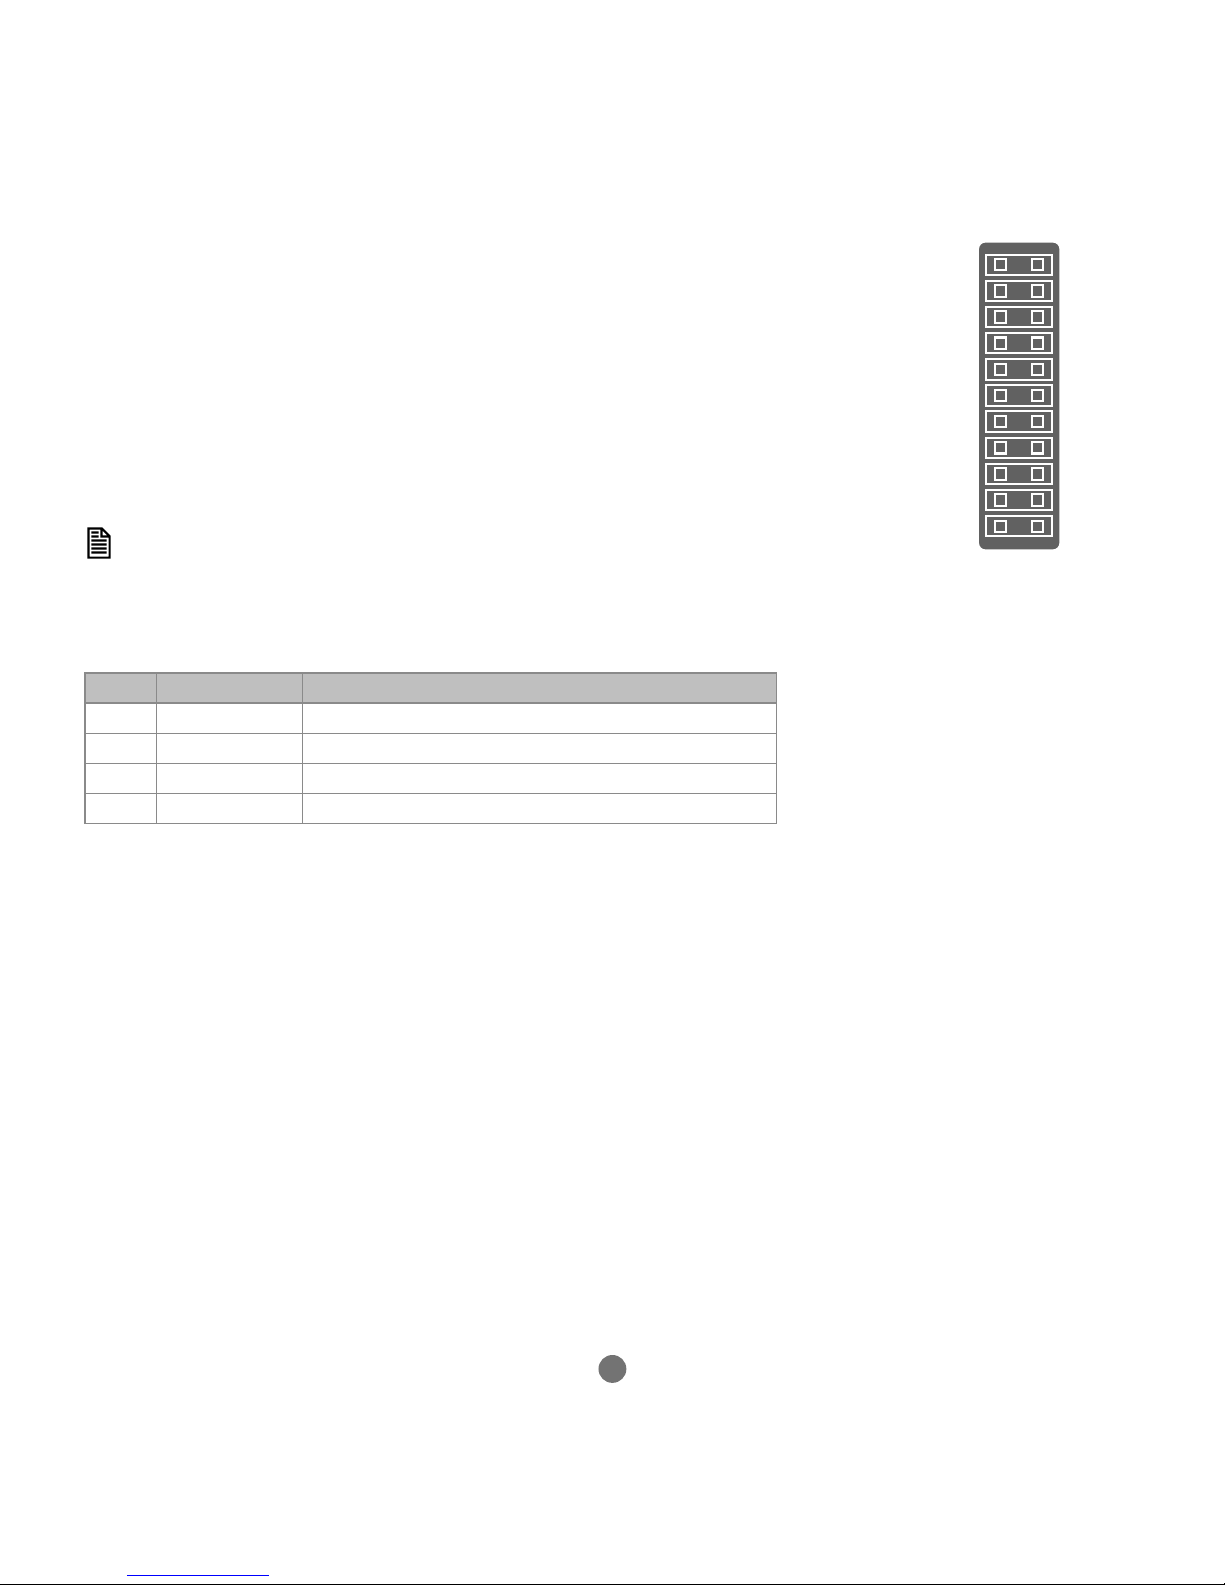
EXPANSION MODULE P874 / P879 - FLEXIBLE AXIS INTERFACE
REGISTRATION CONNECTOR
V0 - V7: Voltage outputs
R4/PS4 - R7/PS7: Bidirectional registration / PSwitch
R0 - R3: Registration Inputs
0V PWR:
P
ower Input
24V: Power Input
V0V: DAC common 0V return
4 axis version uses voltage outputs 0 - 3 only.
LED FUNCTIONS
LED LED Colour LED Function
ok Green ON=Module Initialised Okay
0 Red ON=Module Error
1 Yellow Status 1
2 Yellow Status 2
V0V
V0V
V0
V1
V2
V3
R0
R1
R2
R3
0V PWR
V0V
V0V
V4
V5
V6
V7
R4/PS4
R5/PS5
R6/PS6
R7/P S 7
24V
Page 12
12
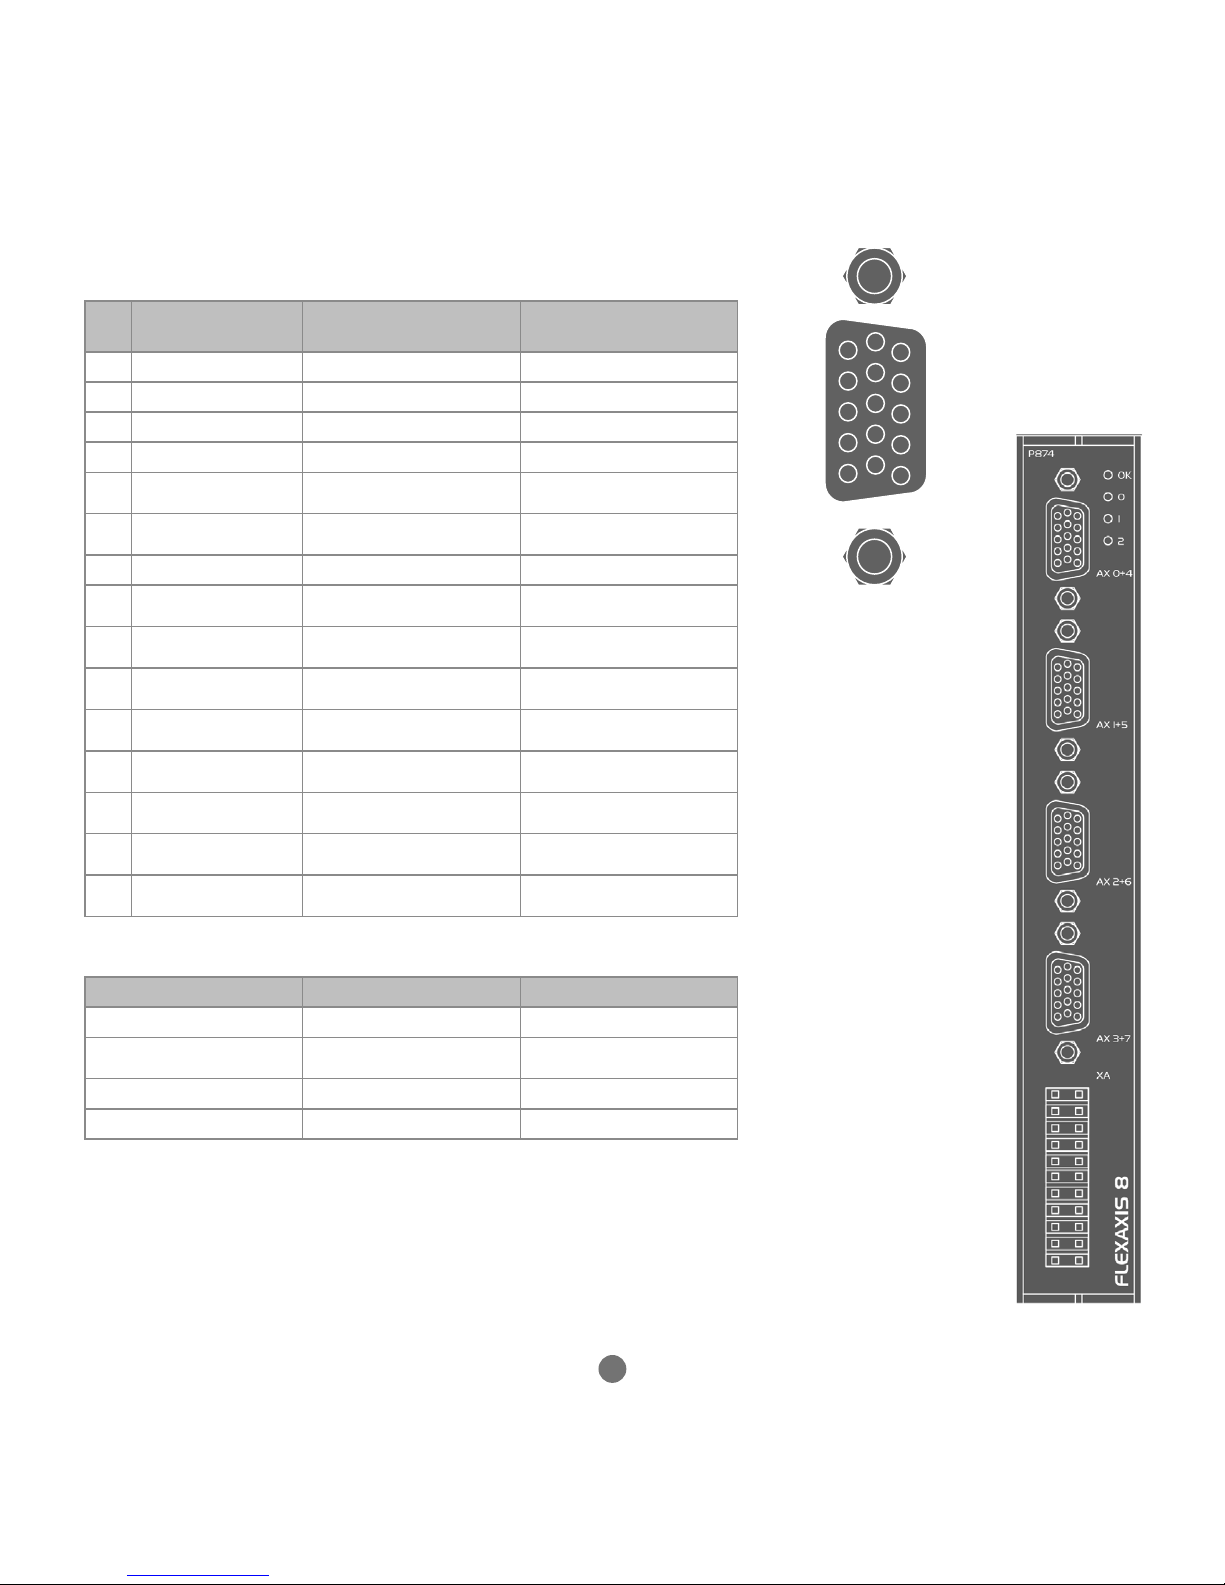
ENCODER CONNECTOR (15 WAY D-TYPE)
Pin
Incremental
Encoder
Absolute Encoder Pulse & Direction
1 Enc. A n Clock n Step.+ n
2 Enc. /A n /Cloc k n St e p.- n
3 Enc. B n -------- Direction+ n
4 Enc. /B n -------- Direction- n
5 0V Enc. 0V Enc. 0V Step.
6 Enc. Z n Data n Enable- n
7 Enc. /Z n /Data n Enable+ n
8 5V* 5V* 5V*
9 Enc. A n+4 Clock n+4 Step.+ n+4
10 Enc. /A n+4 /Clock n+4 Step.- n+4
11 Enc. B n+4 -------- Direction+ n+4
12 Enc. /B n+4 -------- Direction- n+4
13 Enc. Z n+4 Data n+4 Enable- n+4
14 Enc. /Z n+4 /Data n+4 Enable+ n+4
15 0V Enc. 0V Enc. 0V Enc.
*5V supply is limited to 150mA per axis.
Connector 8 Axes (P874) 4 Axes (P879)
1 0 and 4 0
2 1 and 5 1
3 2 and 6 2
4 3 and 7 3
Absolute Encoder is only available on axes 4 - 7 on P874
and 2 - 3 on P879.
6
10
1
5
11
15
1
2
3
4
Page 13
13
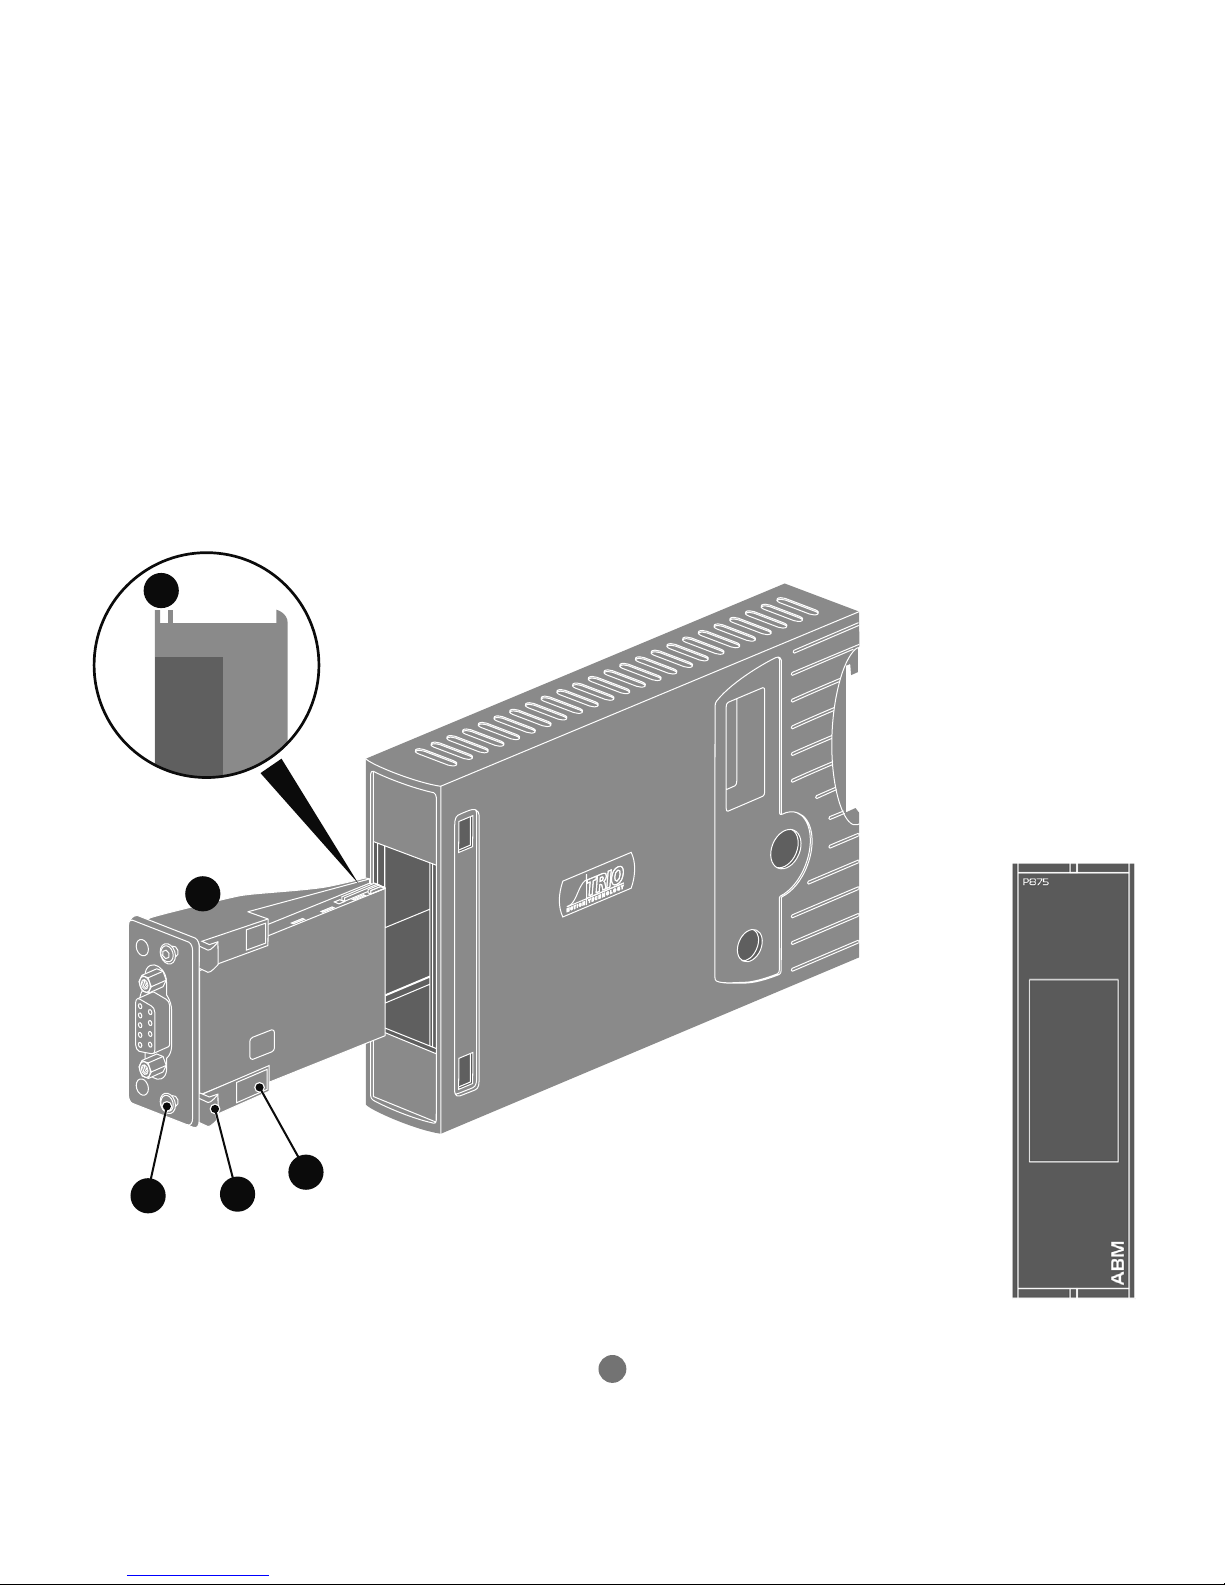
EXPANSION MODULE P875 - ANYBUS® INTERFACE
ANYBUS
®
FITTING
Push the Anybus® module (A) into the Trio Expansion Interface taking care to keep its base in contact with the PCB and align
guide slots (B) with the connector rails inside. Ensure that the moulded hooks (C) on the lower front edge of the Anybus®
module locate under the P875 PCB at the front.
When the module is ush with the face of the Trio Expansion Interface, tighten the two “Torx” head screws (D) to locate the
two lugs (E) and secure the Anybus® module.
To remove the module, reverse this procedure.
The P875 supports Anubus CC M30 Modules.
C
D
A
B
E
Page 14
14
EXPANSION MODULE P876 - ETHERCAT INTERFACE
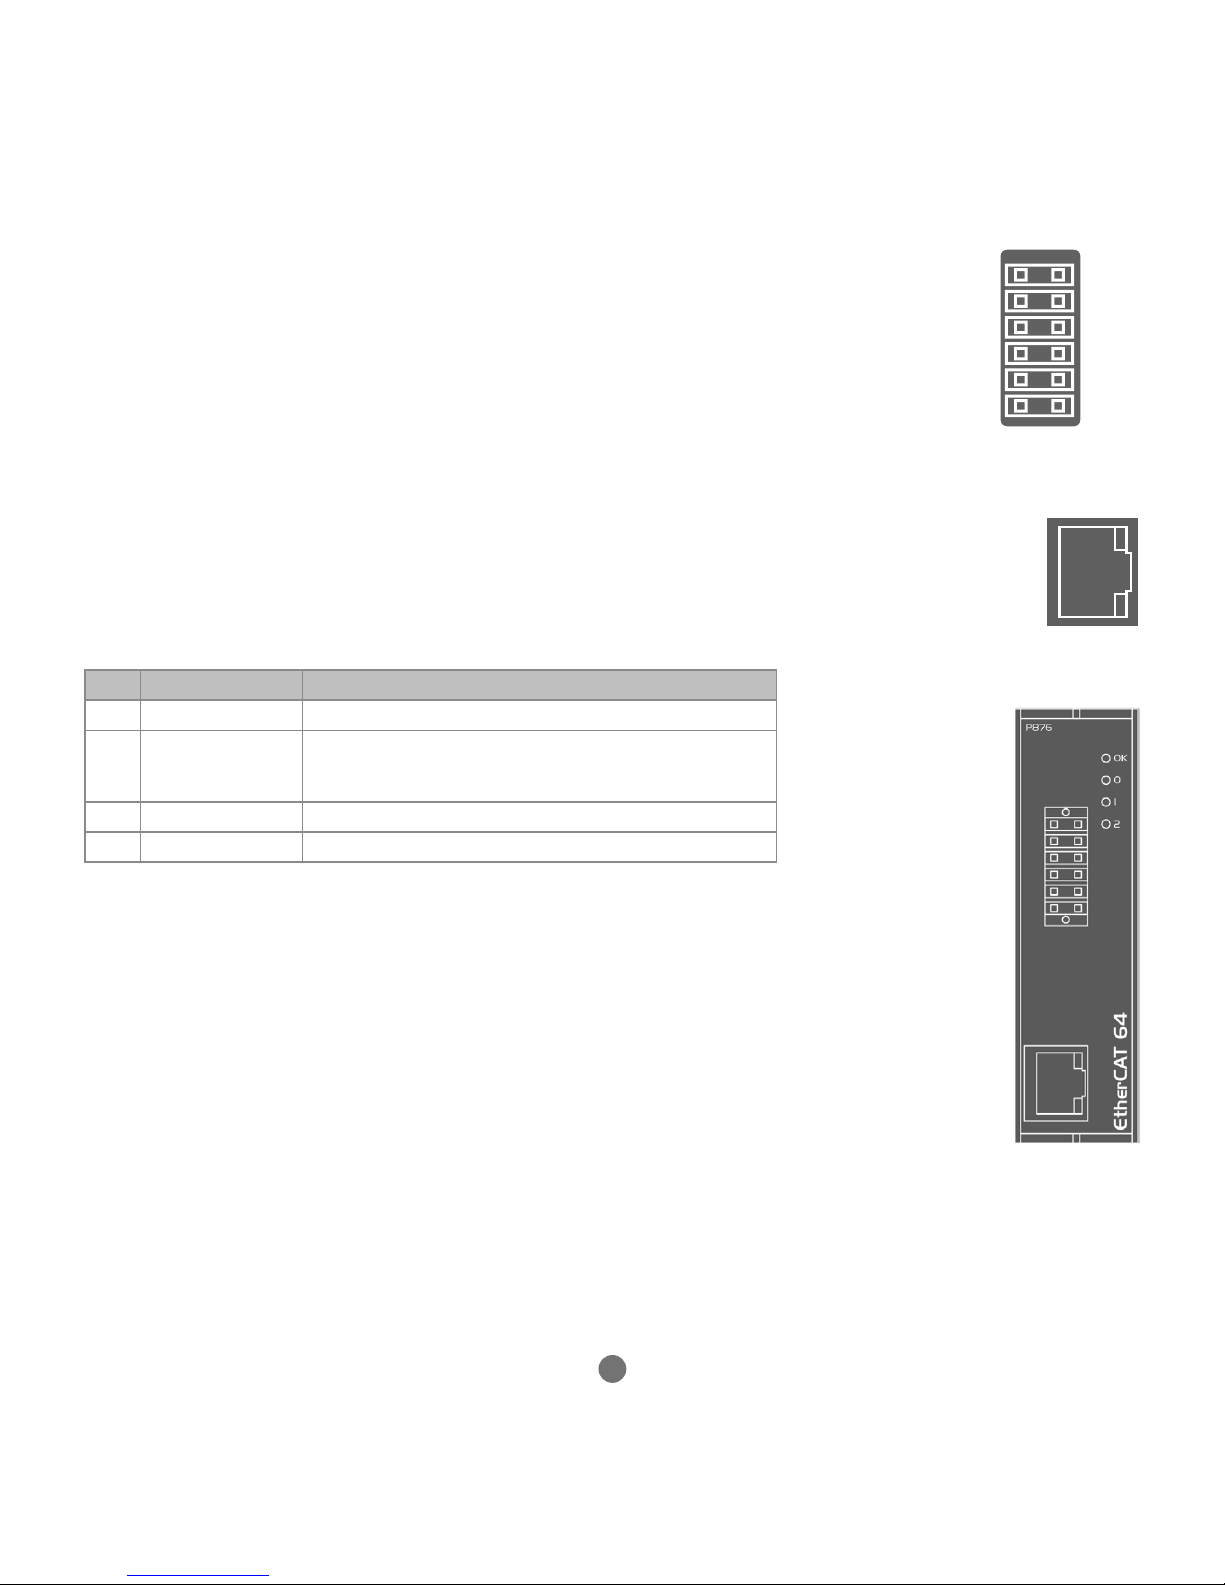
REGISTRATION CONNECTOR
R0 - R7: registration inputs (24V).
0V:
r
egistration common 0V return.
Registration inputs can be allocated to any axis by software.
Also available to software as general purpose inputs.
RJ45 CONNECTOR
100 base-T Ethernet master. Connect to IN of rst slave.
LED FUNCTIONS
LED LED Colour LED Function
ok Green ON=Module Initialised Okay
0 Red
ON=Module Error
SLOW FLASH=Not in Operational State
QUICK FLASH=EtherCAT Error
1 Yellow Status 1
2 Yellow EtherCAT Activity
R0
R1
R2
R3
R0V
R0V
R4
R5
R6
R7
R0V
R0V
Page 15
15
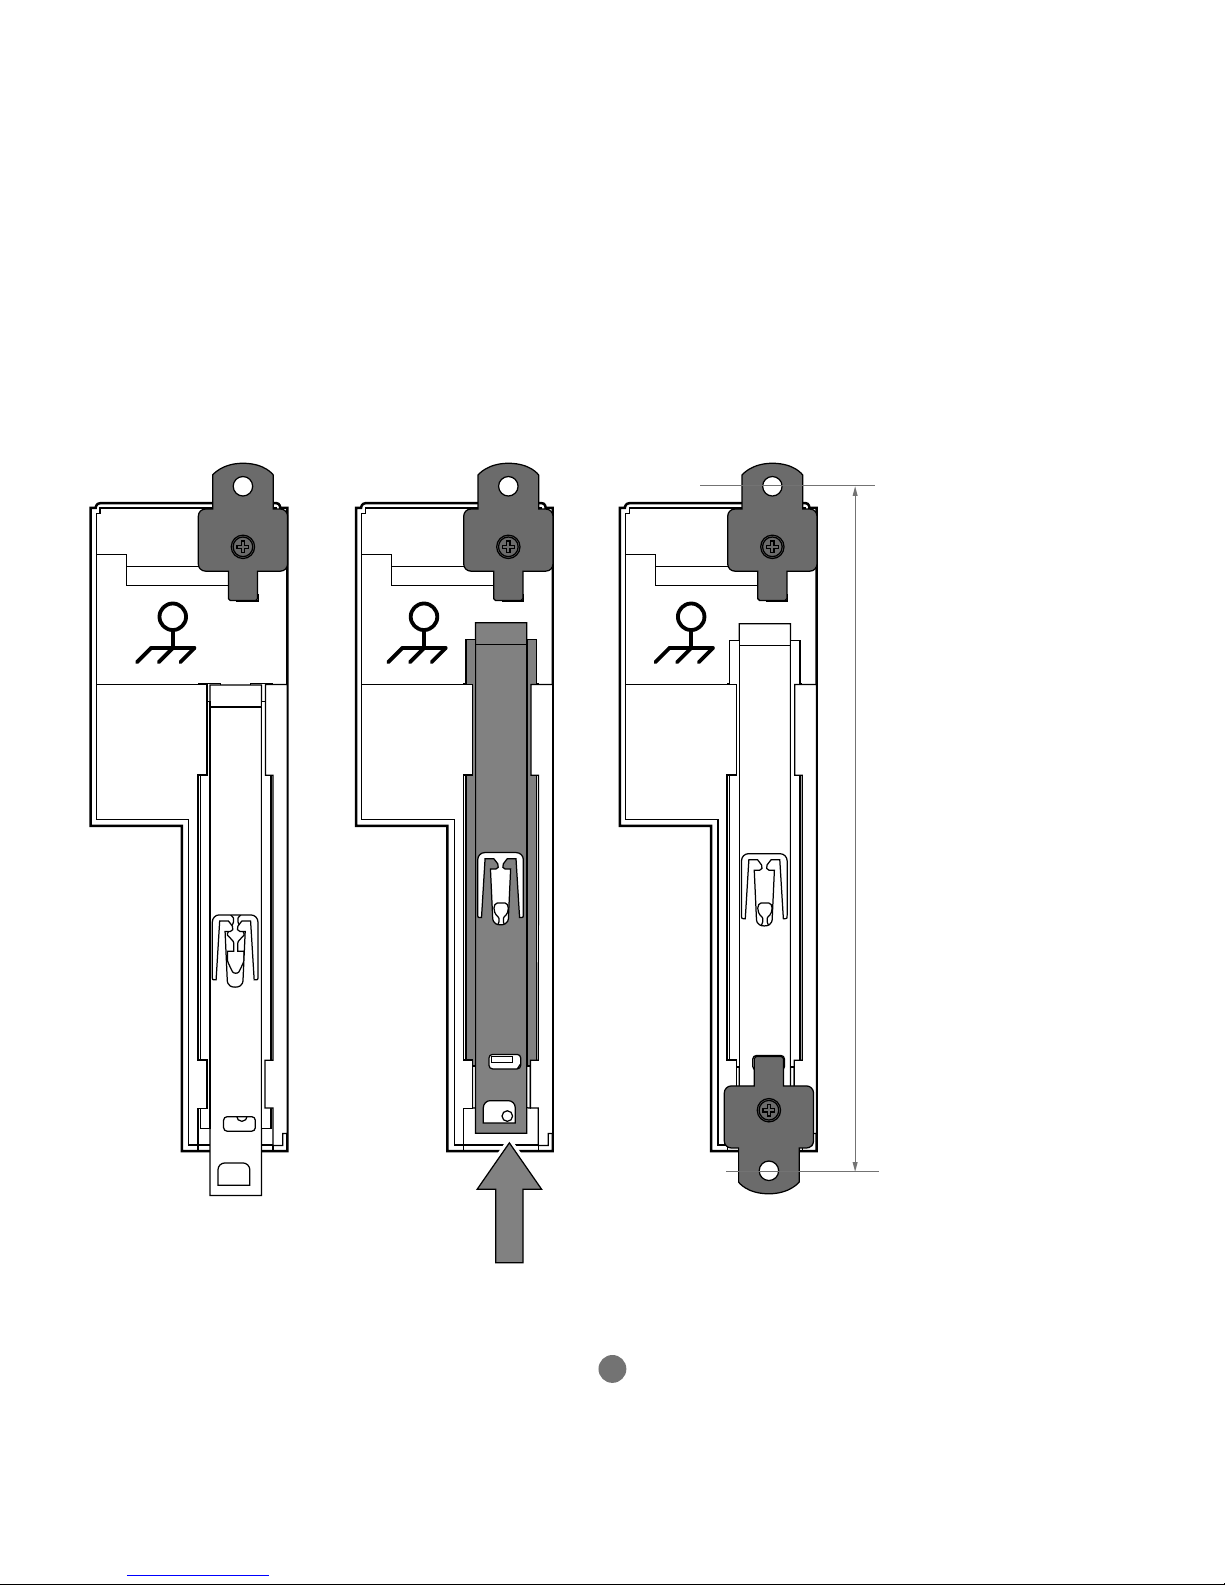
CHASSIS MOUNTING DIMENSIONS (LOOKING FROM REAR)
To mount the controller onto a back plane, remove the 2 mounting clips (included in box) and insert one at the top rear of the
case, by tting the small tab into the rectangular slot and x with the M3 x 6mm screw provided.
The second clip ts to the bottom of the case rear. Line up the DIN rail lever with the hole and slot in the metal chassis, t the
clip into the slot and x it with the M3 x 10mm screw.
ENSURE THAT THE VENTILATION SLOTS AT THE TOP AND BOTTOM OF THE MC664 ARE KEPT CLEAR TO ENSURE A
FREE FLOW O
F A
IR THROUGH THE MODULE.
X X X
195mm
Page 16
UK | USA | CHINA | INDIA
WWW.TRIOMOTION.COM
THE MOTION SPECIALIST
CAD data Drawings to aid packaging and mounting are available in various formats from the Trio web site. Products should be
wired by qualied persons.
Specications may change without notice. E & OE
Quick Start v3 September 2018
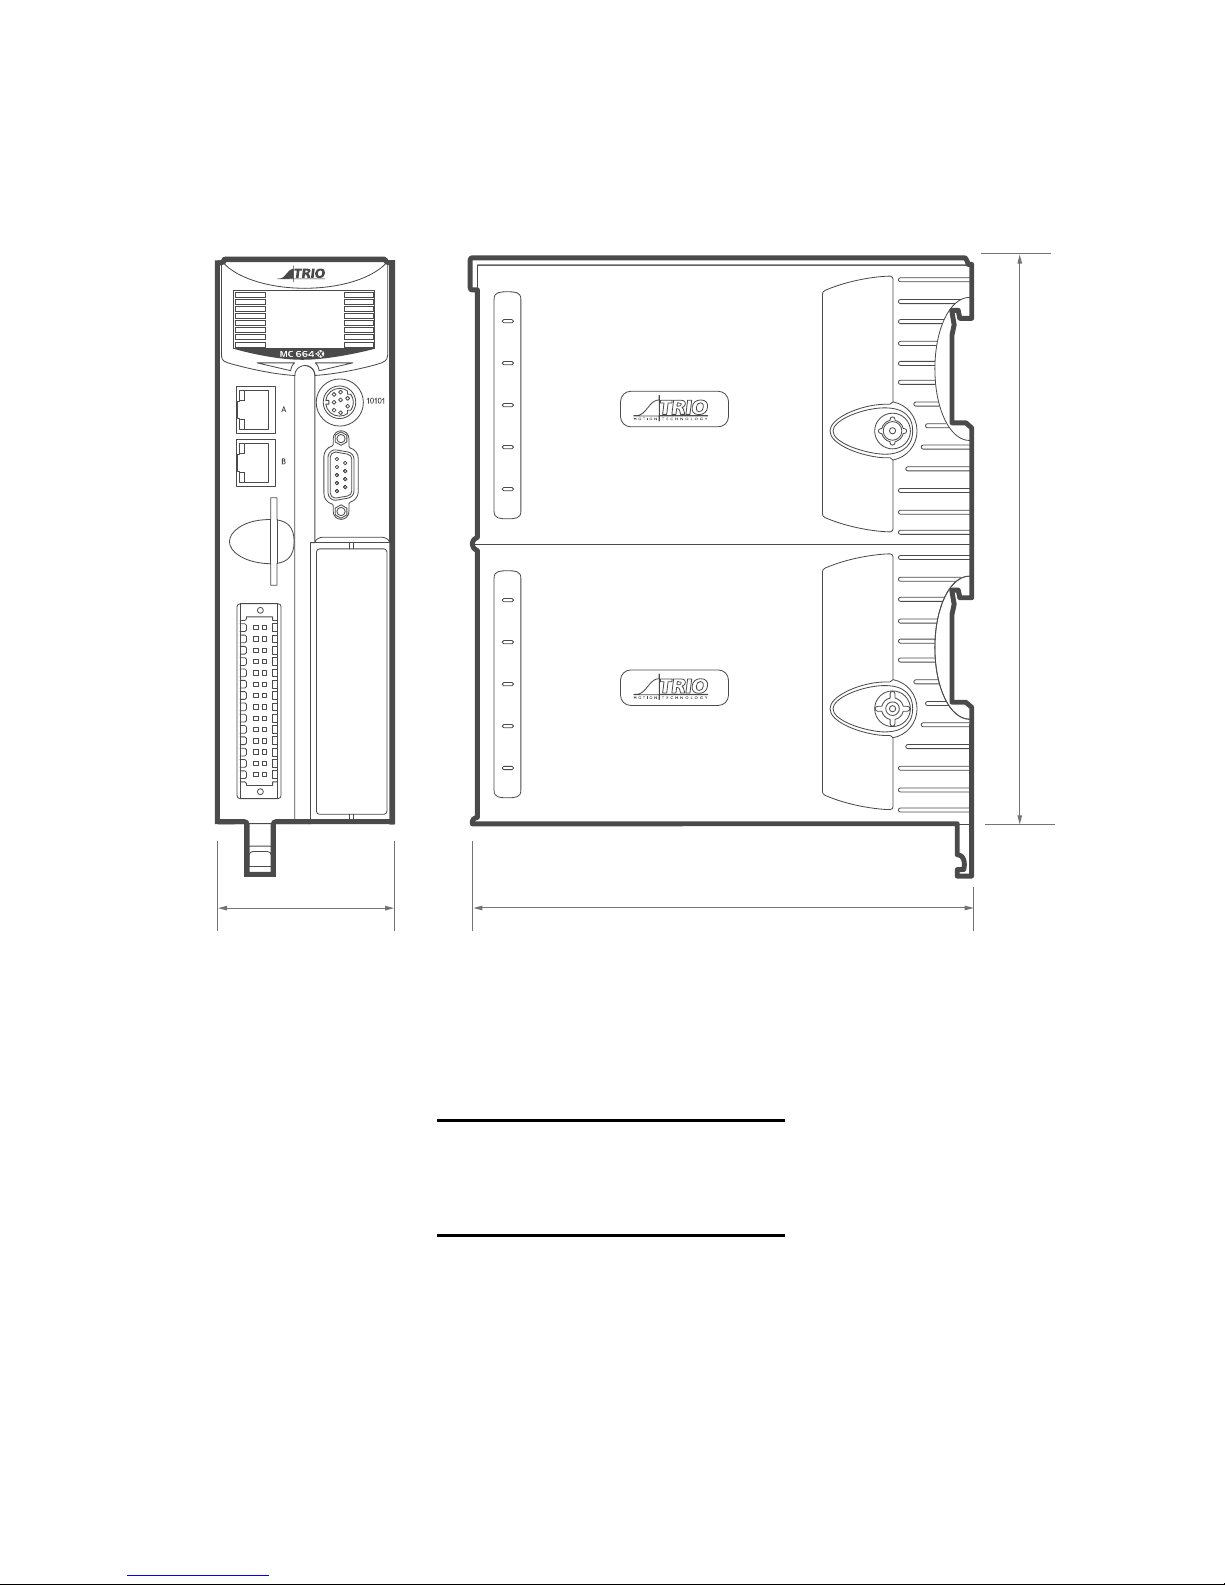
154mm
184mm
56mm
 Loading...