

Page 1
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 12 of 12
User Notes
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 1 of 12
GigaRad Radio System
Point Controller
Model GRX4
Timpdon
Electronics
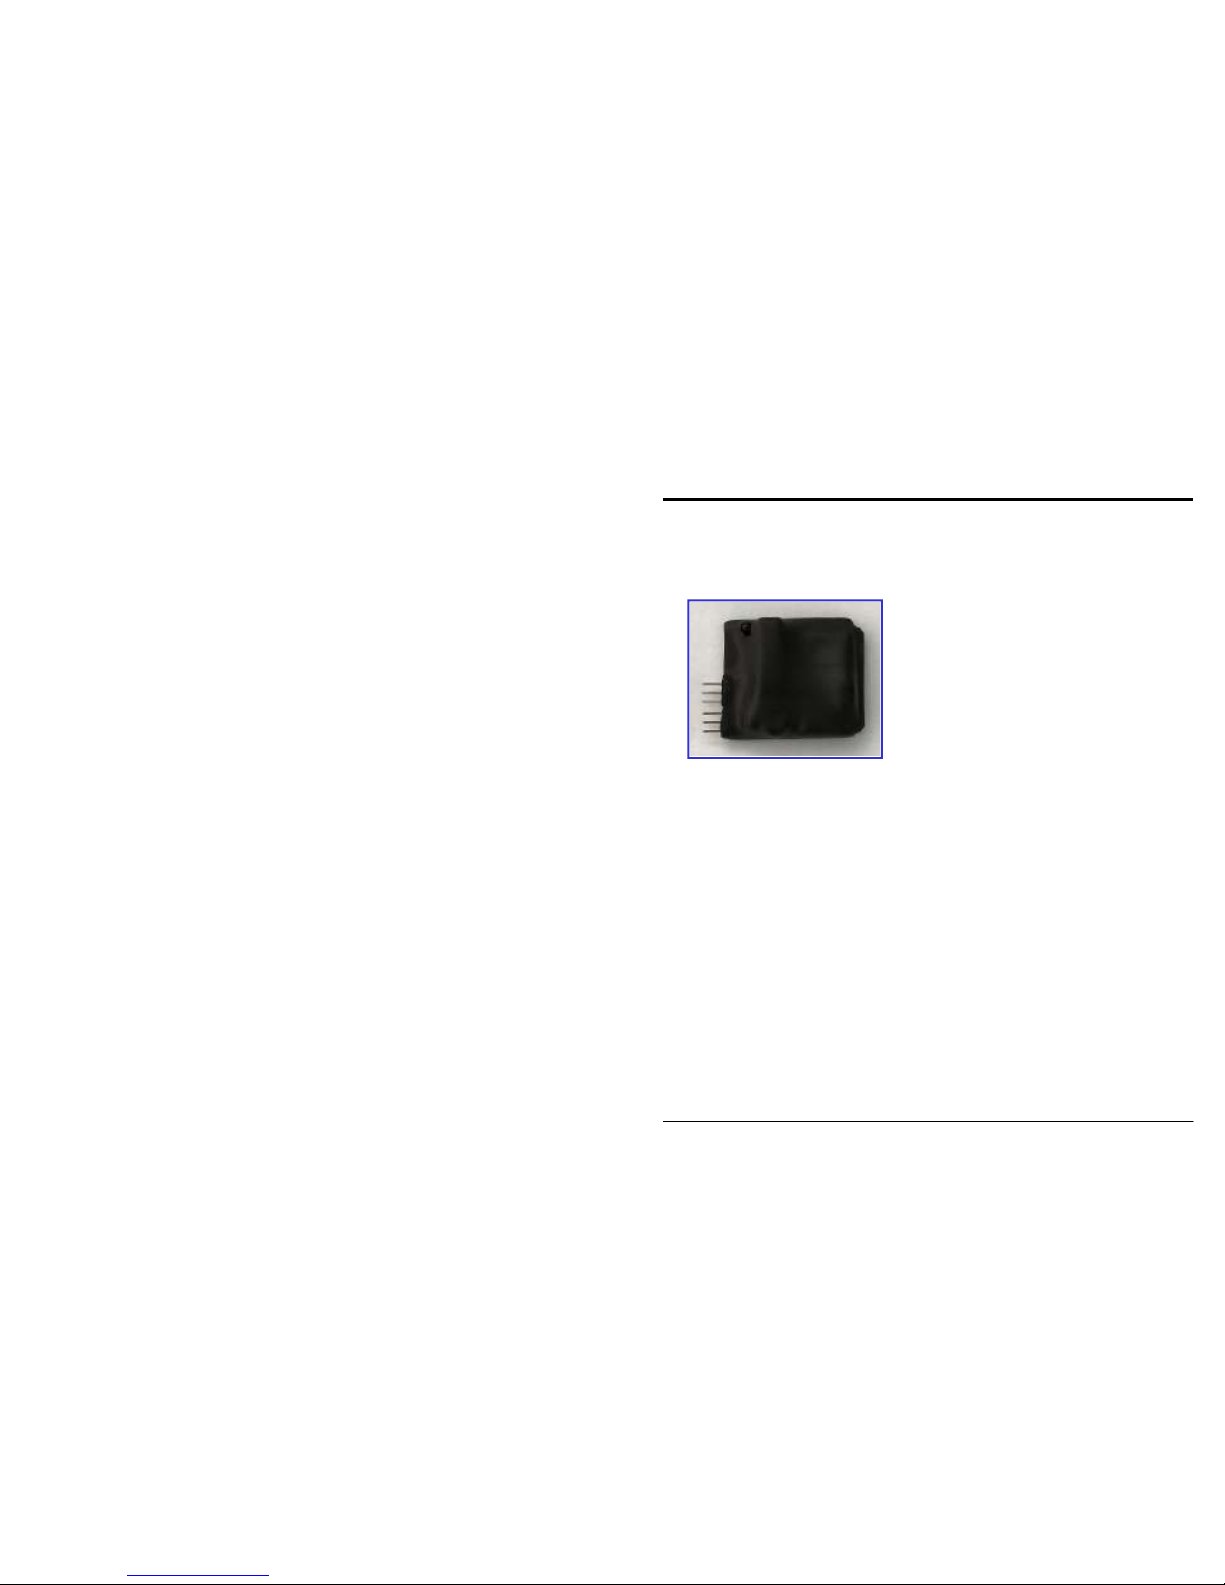
This advanced 2.4 GHz GigaRad Radio
Receiver/Controller is designed to be used
with any model of GigaRad transmitter.
It is designed for the radio control of a single
point using a standard RC servo as the point
motor.
The controller may be user programmed,
in-situ for:
•
Point activation by any one of the four
transmitter Auxiliary switches Aux 1 to
Aux 4.
•
Point set and reset servo positions.
The servo rotation rate is pre-programmed to
give realistic slow speed point operation.
It complies fully with all UK legislation for
licence free operation.
Specification
Frequency 2.4 GHz Radio Control Model Band
RF Sensitivity -94 dBm
Modulation Gaussian Frequency Shift Keying
Range Up to 100 metres with any GigaRad
transmitter, in a normal model railway or
garden environment
Size 47 mm [over pins] x 35 mm x 11 mm
Power Supply 4.8 V to 6V d.c. battery supply
Page 2
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 2 of 12
Introduction
The GRX4 comprises a 2.4 GHz Gigarad radio receiver and point
controller within a single package.
The receiver will operate with any GigaRad transmitter and, during
setup is bound to a particular transmitter, such that it will respond only
to transmissions from that transmitter. It may be re-bound by the user
to another transmitter at any time.
The output from the GRX4 is a standard servo control PWM signal, with
two user programmable stable positions [Set and Reset] and a
controlled rotation rate between these two positions.
The activation of the servo output can be user programmed to respond
to the operation of any one of the four available Auxiliary output
switches on any GigaRad transmitter.
Principles of Operation
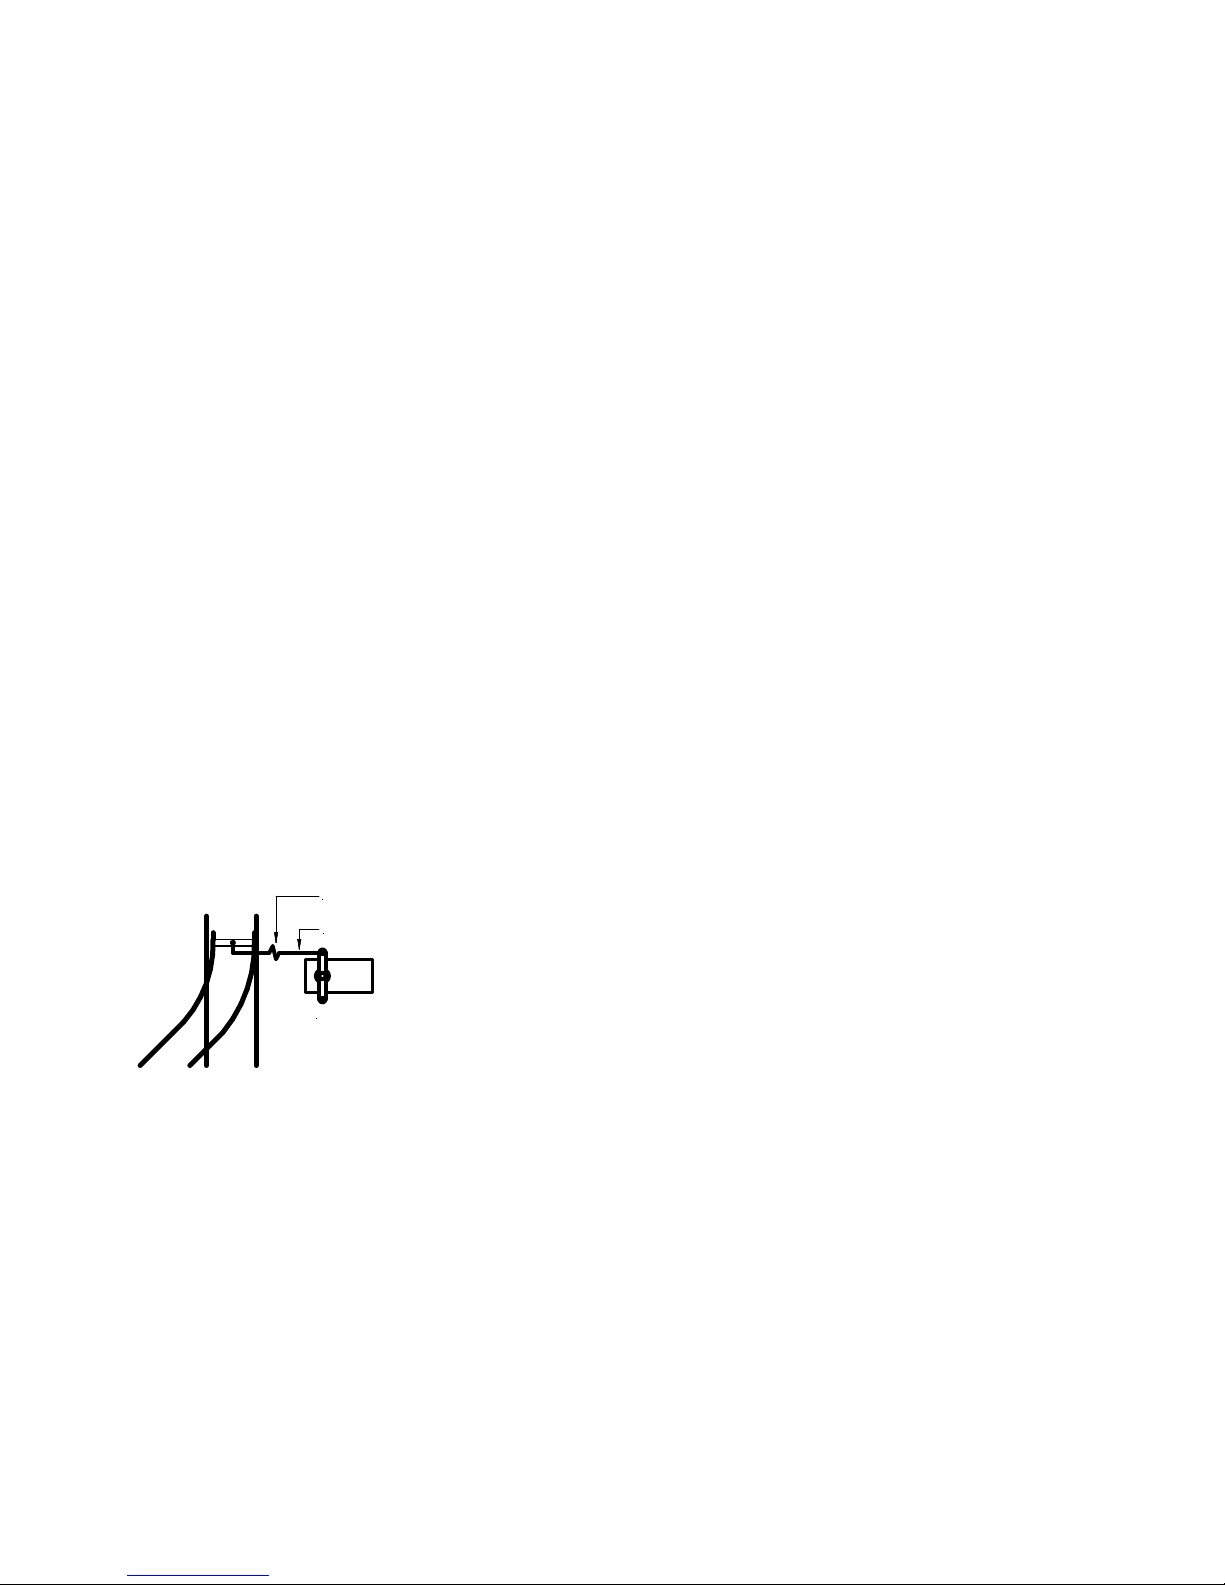
The GRX4 is designed to use any standard RC servo as a point motor,
with movement of the point blades controlled directly by the servo arm,
rotating over a small angle between two fixed positions, set and reset.
Point setting is controlled by any one of the four transmitter auxiliary
switches, with the reset position corresponding to switch off and the
set position to switch on.
Both the set and reset positions of the servo are user programmable
from the transmitter, operating in a special calibration mode.
Point Servo
Mechanical Linkage
Stress Relief
[See Text]
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 11 of 12
User Notes
Page 3
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 10 of 12
User Notes
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 3 of 12
The maximum programmable rotation angle of the servo is constrained
to approximately 25°, centred around the nominal servo centre position,
corresponding to a PWM pulse width of 1.5 ms. This will give a linear
point blade movement of approximately 5 mm, when connected by a 12
mm servo arm, adequate for most track. If greater travel is required, a
longer servo arm may be used.
The rotation rate of the servo arm during operation is automatically
controlled by the GRX4 to give a realistic prototypical rotation period of
approximately 1.7 seconds for the maximum 25° rotation, and pro-rata
for smaller angles.
To minimise the load on the servo motor when the point is locked in
either end position, you are strongly recommended to fit a stress relief
omega loop or Z bend in the connecting linkage between the servo
and the point mechanism. You are also recommended to remove any
built-in snap action point locking mechanism.
Binding
Before use, the GRX4 must be bound to the transmitter with which it is
to be used. Once bound, this process need not be repeated unless you
wish to use a different transmitter.
All binding procedures are undertaken from the transmitter, and no
access to the receiver is required. Refer to the user manual of your
GigaRad transmitter for binding instructions.
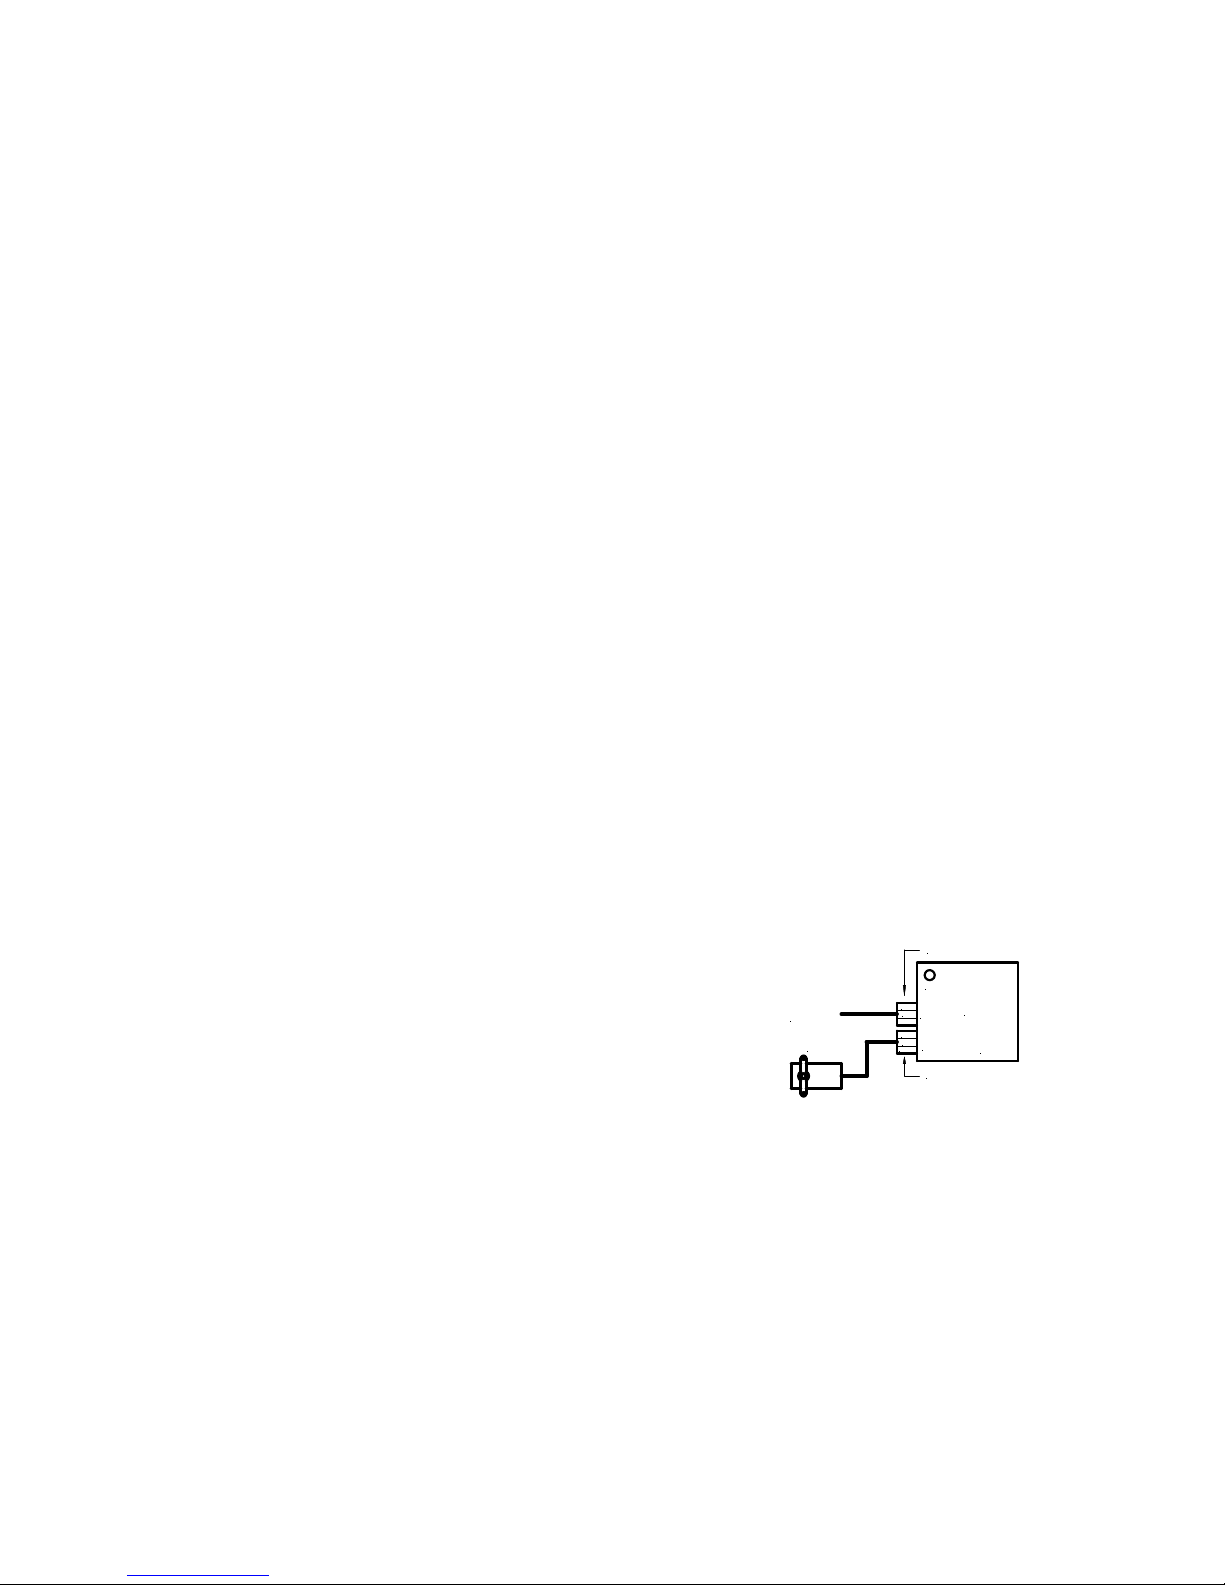
Wiring and Connections
4.8 to 6 V d.c.
Power Supply
GRX4
GigaRad
Receiver/
Controller
LED
Black
Red
Black
Red
Yellow
Power
Point
Servo
Yellow lead this end
Black [or Brown] lead this end
Point Servo
Page 4
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 4 of 12
Notes on Wiring and Connections
1 Connect the servo via its 3 wire plug directly to the GRX4 Point
Servo connector. Ensure that you observe the correct polarity.
2 Connect a d.c. supply to the GRX4 Power connector. Ensure that
you observe the correct polarity. The supply voltage must be
between 4.8 V and 6 V nominal, to match the operating voltage
limits of standard servos.
The point system will only draw significant current while the servo
is in motion, so 4 x AA primary or rechargeable batteries are
perfectly adequate, and should give reasonable battery life.
You are recommended to switch off or disconnect the battery
supply when your layout is not in use, to avoid draining the
batteries unnecessarily.
3 Before use, The GRX4 must be bound to your transmitter, as
described above, and programmed for servo rotation angles
and transmitter Auxiliary control switch allocation. The
calibration procedure is described below.
Servo Mounting and Mechanical Set Up
For optimum performance and ease of calibration you are strongly
recommended to follow the guidelines given here for servo mounting
and set up.
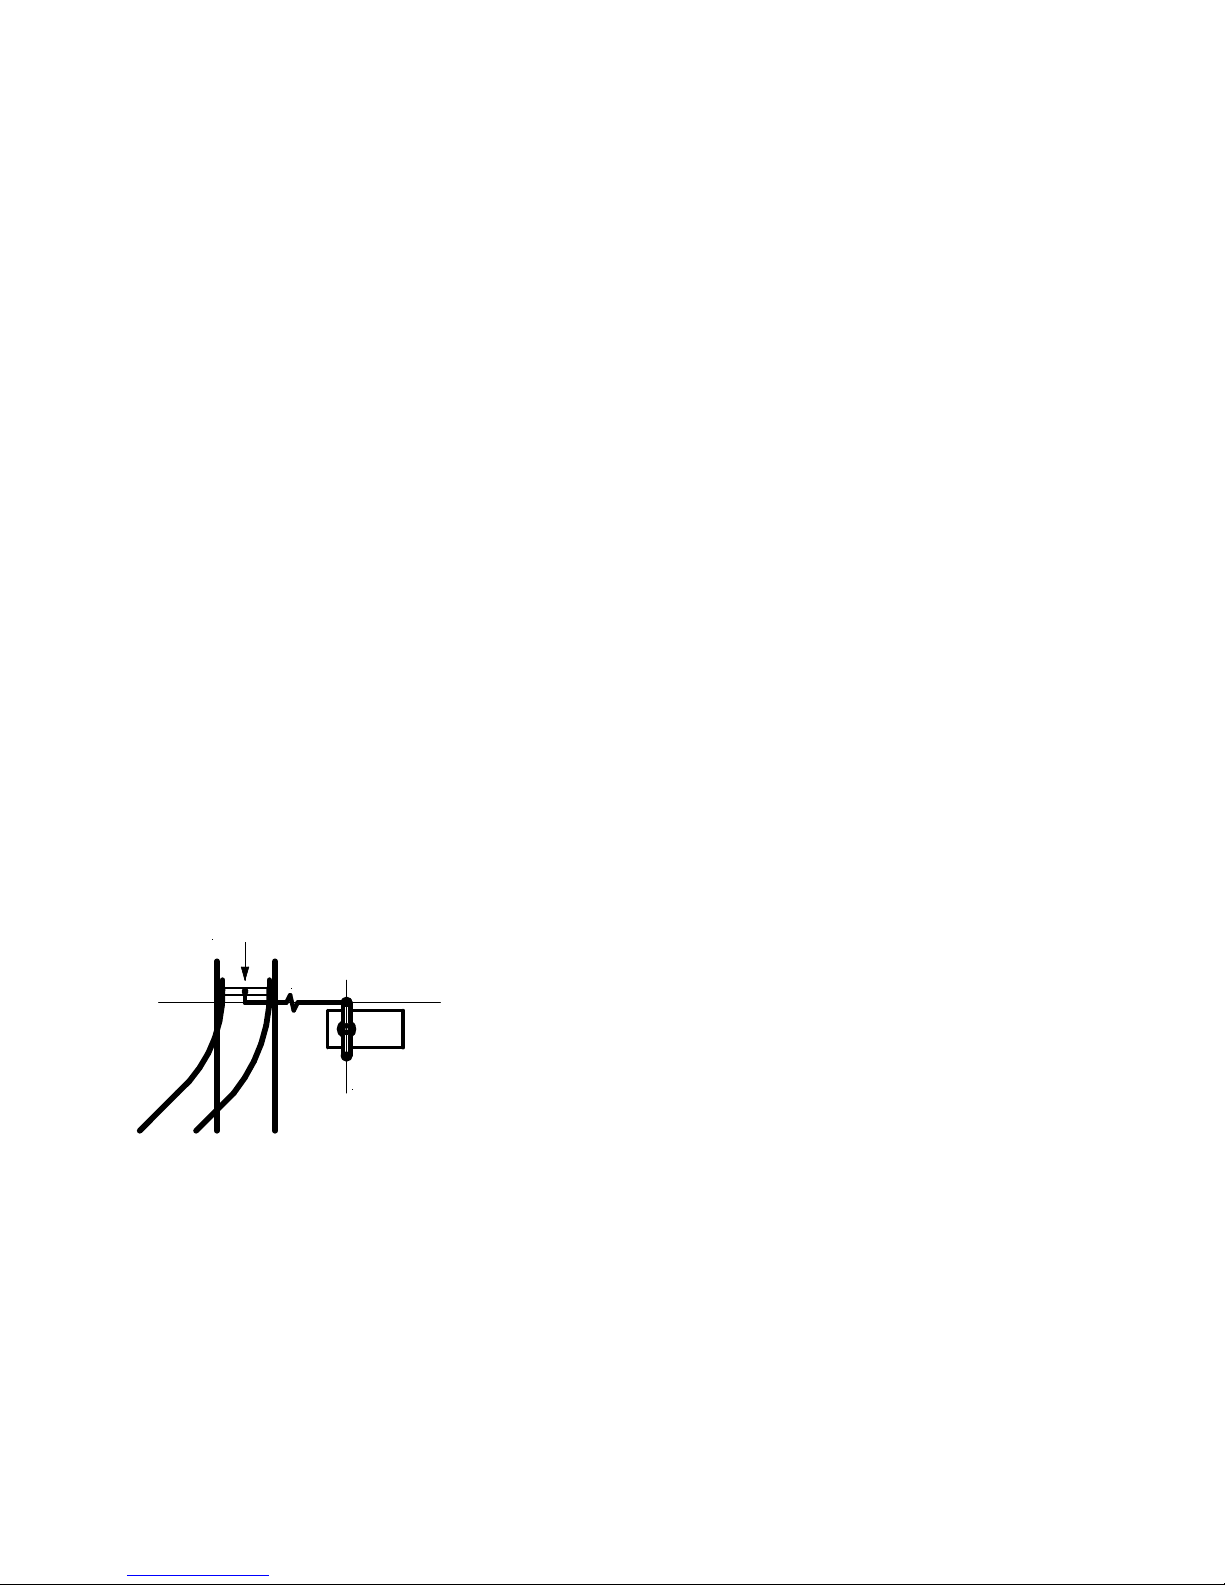
Operating linkage at 90
degrees to straight track
Servo arm parallel
to straight track
Point Blades in
Mid Position
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 9 of 12
Indicator LED
At all times, the GRX4 indicator LED shows the current operational
status of the unit.
LED Indication Interpretation
LED Off No power to GRX4.
Fast Flash No valid radio pulses detected at power
[ 5 per second ] up.
Transmitter not on, or not bound.
LED On Bind procedure successful.
Normal operation.
Slow Flash Loss of valid radio pulses following
[ 1 per second ] normal operation.
On Power Up
On power up of the GRX4, the point will immediately move to the reset
position, and remain there until the first valid data packet has been
received from the transmitter. It will then assume the position specified
by the current position of the appropriate transmitter Auxiliary switch.
On loss of Radio Communication
If radio communication is lost, for any reason, during normal operation,
the point will remain in its last valid controlled state, until radio
communication is restored or until power is removed from the GRX4
and re-applied.
Page 5
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 8 of 12
Calibration Procedure
continued
4 Now power up the transmitter and immediately—within two
seconds—set the Aux 1 switch On and then Off. This instructs
the transmitter and GRX4 to enter Calibration mode. The
Calibration LED on the transmitter will go On, in addition to the
Transmit LED.
5 Set switches Aux2 [C1] , Aux 3 [C2] and Aux 4 [C3] to select
the calibration function to be performed, as listed in the table
above.
6 For servo position calibration, use the transmitter speed control
to set the servo to the required position for the selected function,
by visual examination of the point blade positions.
Take care that you do not attempt to move the servo to a position
where the point blade is solidly jammed in either the set or reset
position. This will overload the servo as it attempts to reach a
position it can not achieve and will result in high power
consumption, servo over-heating and, in worst case, servo
damage through electrical failure or stripped gears.
7 For Operating switch selection, simply select the switch to be
used according to the table. Remember that the last switch
selection saved will over-ride any previous selection.
8 When the desired SETTING has been completed, turn the Aux 1
switch [Save Cal] On and then Off. The current servo position or
auxiliary switch setting will be saved to non-volatile memory
within the GRX4 and used thereafter during normal operation,
until re-calibrated.
9 Repeat Steps 5 to 8, as required, for any other settings requiring
calibration. You need only calibrate those settings which you wish
to change.
10 Once all required calibrations have been completed, turn the
transmitter Off to exit Calibration mode.
11 When the transmitter is next turned On, the point controller will
operate with all new calibrations operational.
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 5 of 12
1 Mount the servo so that the point operating linkage will be
approximately at 90° to the straight track when in use. At this
stage, do not connect the operating linkage to the servo.
2 Connect the servo to the GRX4. Power up and bind the GRX4 to
the transmitter.
The factory default settings for the GRX4, as shipped, are:
•
Reset Servo PWM = 1.50 ms [central]
•
Set Servo PWM = 1.55 ms [rotation angle =
approx. 10°]
•
Transmitter operating switch = Aux 1
3 Set the transmitter Aux 1 switch to Off = Reset.
The servo will take up the factory default position, corresponding
to a servo PWM pulse width of 1.50 ms—i.e. central.
Fit the servo arm to the servo so that it is parallel to the
straight track.
4 Now set the transmitter Aux 1 switch to On = Set, and check
that the servo arm rotates approximately 10°. Do not worry if the
servo rotation direction is opposite to that required. This will be
corrected during calibration.
5 Reset the transmitter Aux 1 switch to Off = Reset, fit the
operating linkage between the point and the servo, and adjust its
length so that the point blades are roughly midway between the
set and reset position, with the servo arm positioned as
described in Step 3.
6 This completes the mechanical set up procedure. You may now
proceed to calibrate the GRX4 for final Set and Reset positions
for the point, and assign the transmitter Auxiliary operating
switch required for operation [if different from Aux 1], as
described below.
7 You may wish to experiment with calibration before fitting the
point operating linkage described in Step 5, in order to familiarise
yourself with the procedure, without risking damaging the servo
by accidental mis-setting.
Page 6
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 6 of 12
Calibration
The GRX4 incorporates the following user calibration facilities
•
Point Reset Servo position.
•
Point Set Servo position.
•
Selection of transmitter Auxiliary switch to be used for
point control.
All calibrations are performed using the GigaRad transmitter, and no
access to the GTX4 is required.
For Point Set and Reset position calibration, the point setting is
adjusted using the transmitter speed control knob, and the required
setting determined by visual observation of the point blade position.
For operating switch selection, the required Auxiliary switch is simply
chosen.
Six calibration selections can be made, each selected individually by the
setting of transmitter switches Aux2 [C1], Aux 3 [C2] and Aux 4
[C3], with the transmitter operating in a special Calibration mode.
Once the appropriate selection has been made, it is saved to nonvolatile memory by setting the transmitter Aux 1 [Save Cal]
transmitter switch On and then Off.
Once set, all calibrations are retained in non-volatile memory and will
remain active until changed again, even after power has been removed
from the GRX4 and re-applied.
Before attempting any calibration, ensure that there are no other
GigaRad receivers or controllers powered up which are already bound
to the transmitter to be used, other than the one to be calibrated.
Timpdon Electronics Tel: 0161 980 7804 Issue 1 — November 2016
www.timpdon.co.uk Page 7 of 12
Calibration Switch Settings
For the GRX4, transmitter calibration switch settings are as follows:
Calibration Aux Switches
A4 A3 A2
C3 C2 C1
Point Reset Position Off Off On
Point Set Position Off On Off
Point Operating Switch
Aux 1 Off On On
Aux 2 On Off Off
Aux 3 On Off On
Aux 4 On On Off
Calibration Procedure
1 First ensure that the GRX4 is bound to the transmitter and is
operating normally.
2 Then turn the transmitter Off.
3 Set the transmitter Speed knob to mid position.
This is important to ensure that, on entry to calibration, the servo
will not attempt to move outside its available operating range,
constrained by the point operating linkage, to a position it can not
achieve.
4 With the transmitter powered Off, set the Auxiliary switches as
follows:
Aux 1 = Off
Aux 2 = On
Aux 3 = On
Aux 4 = On
 Loading...