

Page 1
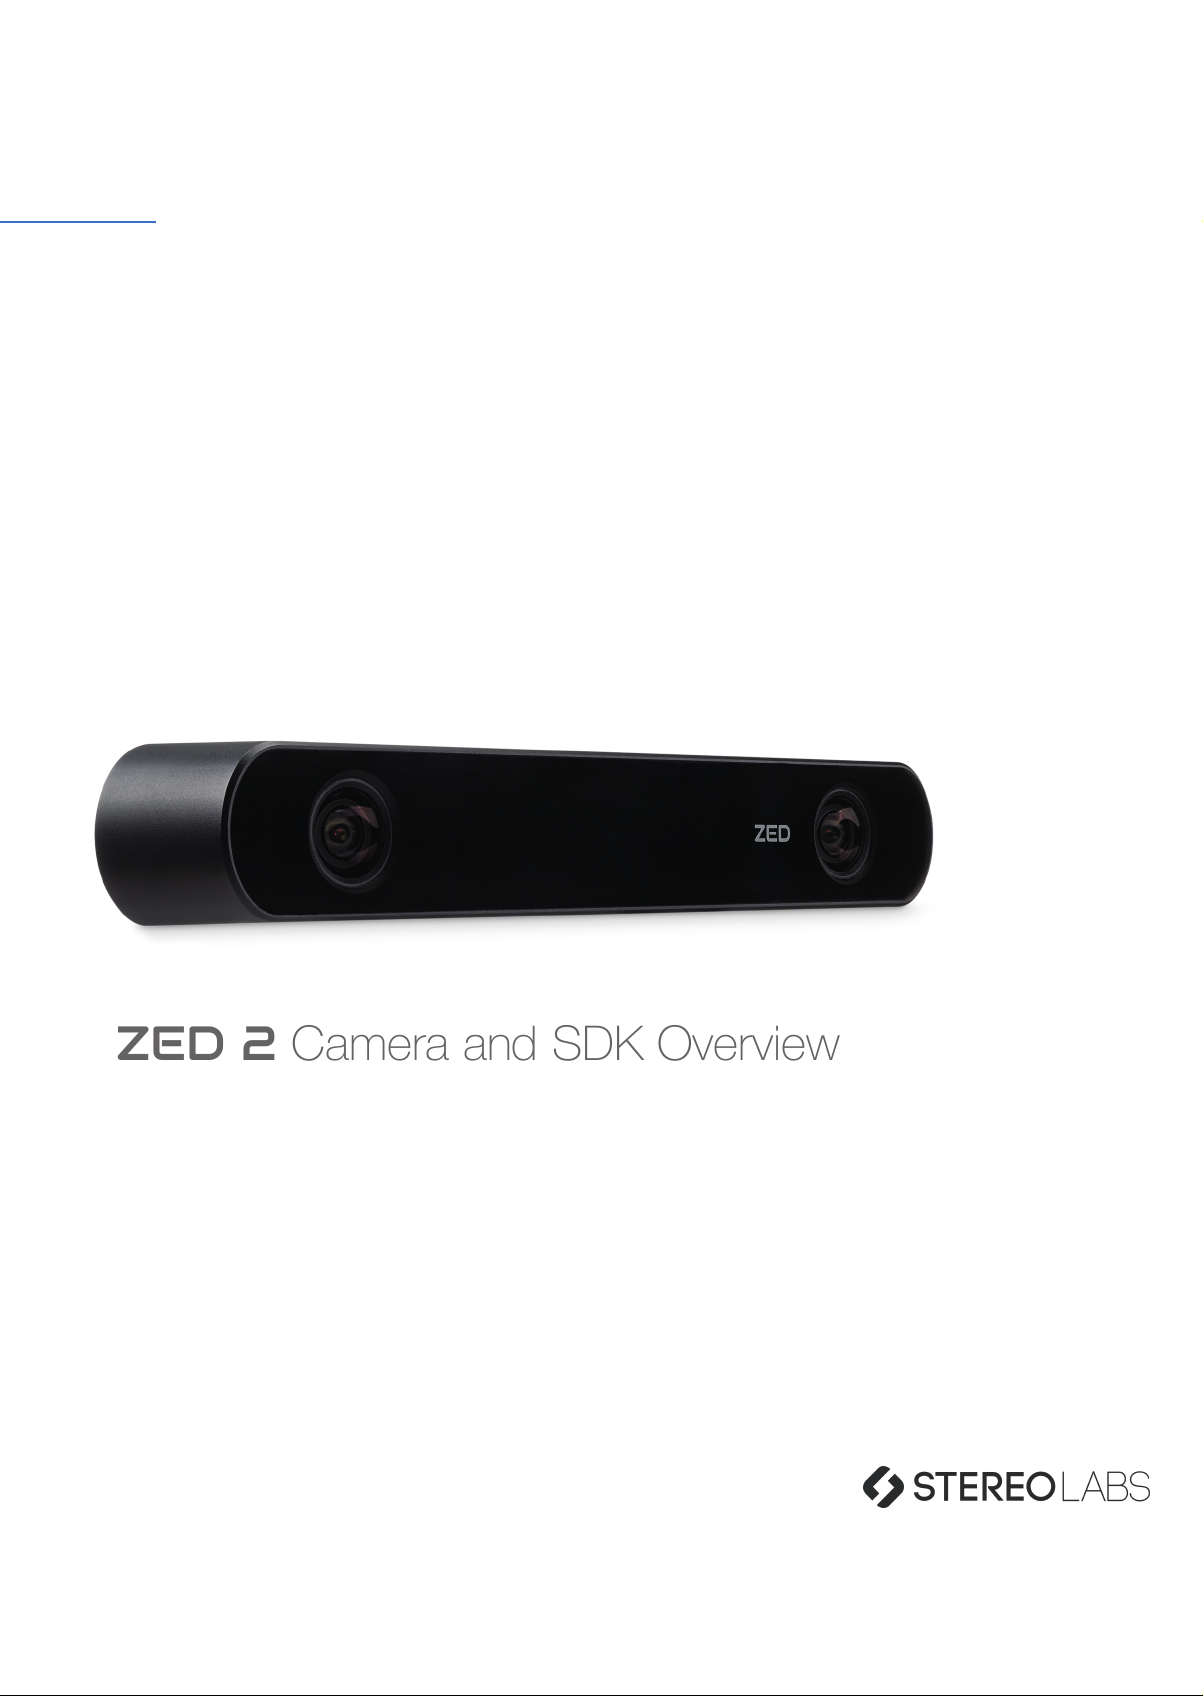
ZED 2
ZED 2 Camera and SDK Overview
The ZED 2 is a stereo camera that provides high definition 3D video and
neural depth perception of the environment. It has been designed for the
most challenging applications, from autonomous navigation and mapping to augmented reality and 3D analytics.
Page 2
ZED 2
Overview
Spatial Object Detection
Detect and track object with spatial context. By
combining AI and 3D the ZED 2 localizes the objects in
space and provides the tools to create the next-generation spatial awareness.
All-Aluminium Case
The ZED 2 comes with a more robust all-aluminium
enclosure with thermal control that compensates
focal length and motion sensors biases.
Camera Control
The ZED 2 is a UVC video camera with low level access
to the device. It provides control over all the camera
parameters such as exposure, gain, sharpness, etc.
General Specifications
Camera
Neural Depth Sensing
The ZED 2 is the first stereo camera that uses neural
networks to reproduce human vision, bringing stereo
parception to a new level.
Built-in Sensor Stack
The most extensive sensor stack is avaialable on ZED
2. Togheter with inertial data, the ZED 2 also captures
elevation and magnetic field in real-time.
Cloud Connected
Monitor and control your camera remotely. Using the
dedicated cloud platform, capture and analyze spatial
data anywhere in the world. Manage your application
remotly and update you camera at an time.
Sensors
Output Resolution
Side by Side 2x (2208x1242) @15fps
2x (1920x1080) @30fps
2x (1280x720) @60fps
2x (672x376) @100fps
Field of View Max. 110°(H) x 70°(V) x 120°(D)
Interface USB 3.0/2.0 - Integrated 1.2m cable
Depth Range 0.3 m to 20 m (1 to 65.6 ft)
Depth Accuracy < 1% up to 3m
< 5% up to 15m
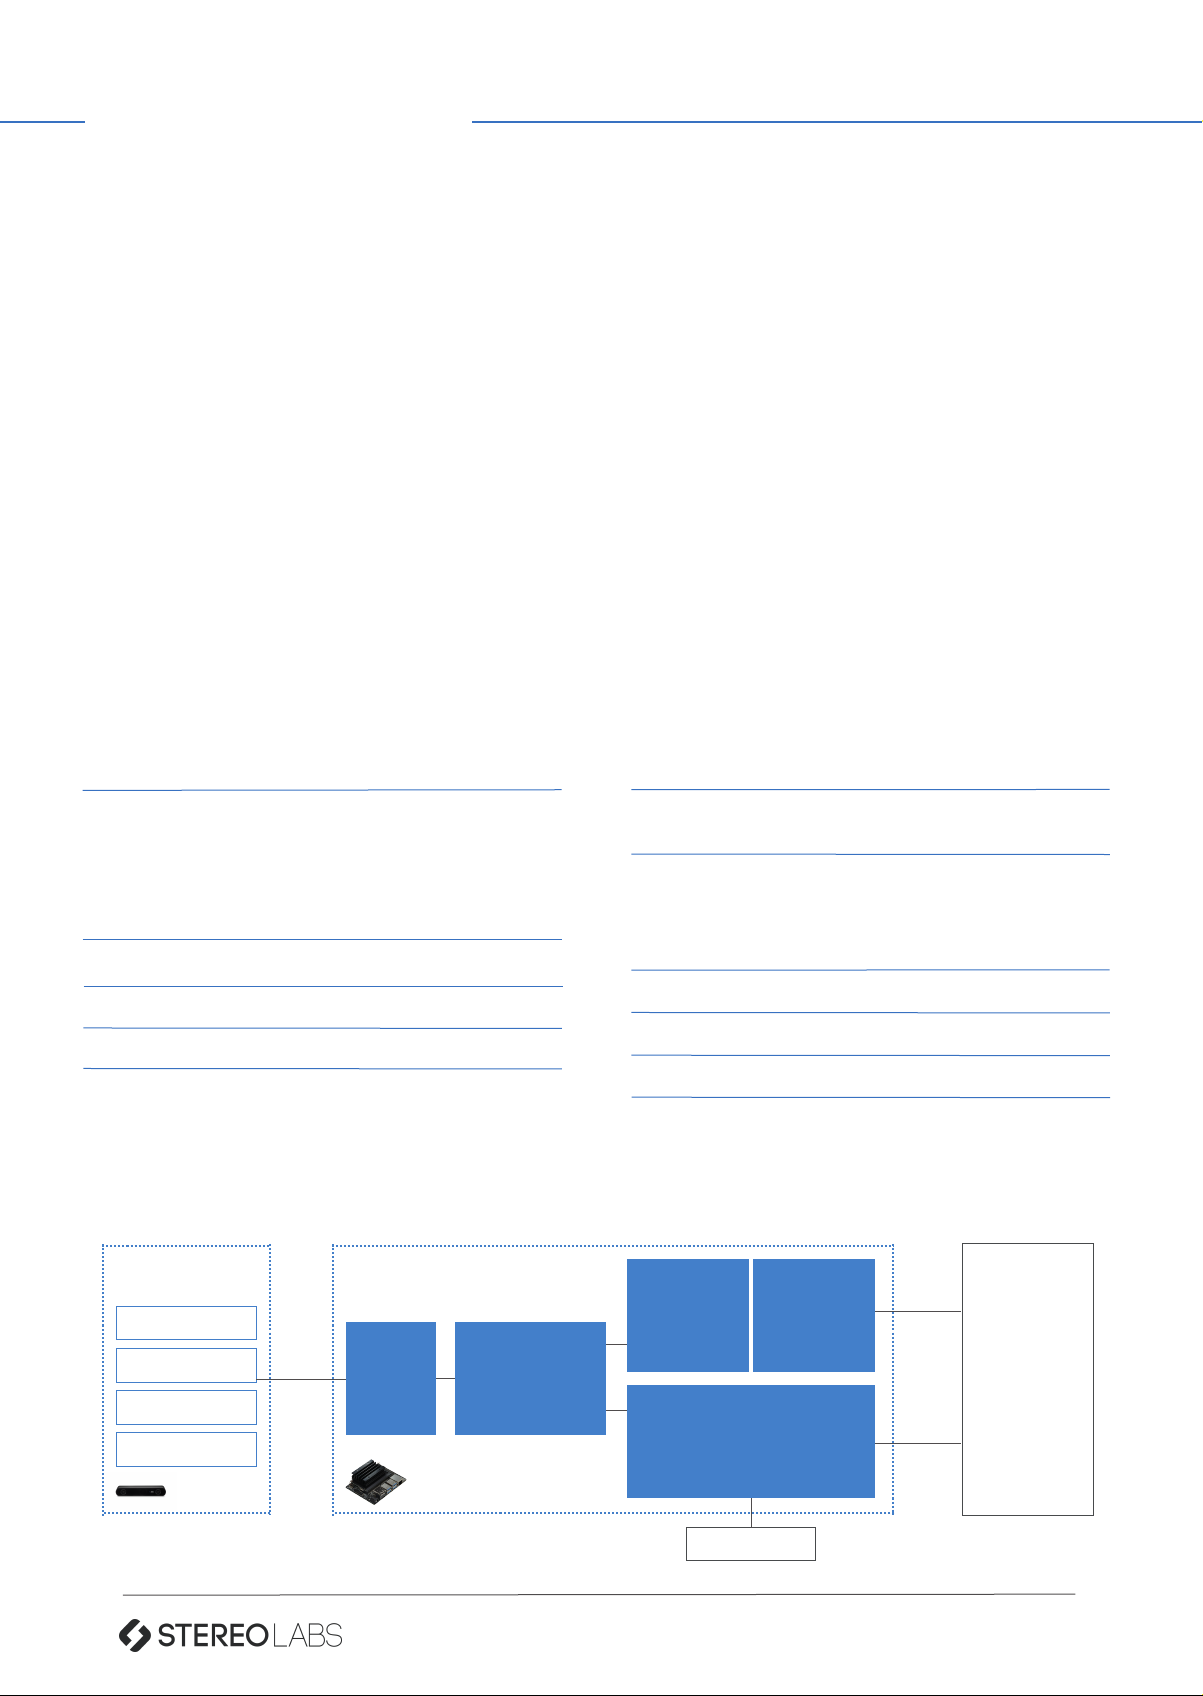
Functional SDK Diagram
ZED 2
STEREO CAMERA
IMU
USB 3.0
BAROMETER
MAGNETOMETER
ZED SDK
SENSOR
FUSION
Jetson Nano / TX2 / Xavier
Desktop
NEURAL
DEPTH PERCEPTION
Motion Gyroscope, Accelerometer
Magnetometer
Environmental Barometer
Temperature
Physical
Dimensions 175 x 30 x 33 mm (6.89 x 1.18 x 1.3’’)
Weight 166g (0.36 lb)
Operating Temp. -10°C to +45°C (14°F to 113°F)
Power 380mA / 5V USB Powered
STATIC
ENVIRONMENT
MAPPING
VISUAL-INERTIAL LOCALIZATION
STEREO SLAM
Fusion
DYNAMIC
OBJECTS
APPLICATION
LAYER
External Sensors
Rev 1 specifications are subject to change without notice - 2019 - All rights reserved.
www.stereolabs.com
Page 3
ZED 2
Detailed Specifications
Dual Image Sensors
Sensors
Sensor Type
Array Size
Pixel Size
Shutter
Output Resolution (Side by side)
Output Format
Max S/N Ratio
Dynamic Range
Sensitivity
1/3” 4MP CMOS
2688 x 1520 pixels
2μm x 2μm
Electronic synchronized rolling shutter
2x (2208x1242) @15fps cropping mode
2x (1920x1080) @15/30fps cropping mode
2x (1280x720) @15/30/60fps binning 2x2 mode
2x (672x376) @15/30/60/100fps binning 4x4 mode
YUV 4:2:2 - UYVY (8bits)
38.3 dB
64.6 dB
1900 mV/Lux-sec
Motion/Environmental Sensors
Inertial Measurement Unit
Accelerometer Range +/- 8G
Accelerometer Resolution 0.244 mg
Accelerometer Noise Density 3.2 mg
Gyroscope Range +/- 1000 dps
Gyroscope Resolution 0.03 dps
Gyroscope Noise Density 0.16 dps
Sensitivity Error +/- 0.4%
Output Data Rate 400 Hz
Magnetometer
Magnetic Field Range +/- 2500 μT (z)
+/- 1300 μT (x,y)
Magnetic Field Resolution 0.3 μT
Lenses
Baseline 120 mm (4.7’’)
Focal Length
Field of View
Aperture
TV Distortion 5.07%
2.12mm (0.08’’)
Max. 110°(H) x 70°(V) x 120°(D)
f/1.8
System Requirements
Supported OS
Windows 10 - 64 bit
Ubuntu 16.04/18.04 - 64 bit
Debian, CentOS (via Docker)
Jetson L4T
CPU
Dual-core ≥ 2.4GHz processor
Minimum 4GB RAM
GPU
NVIDIA GPU ≥ 2GB Memory
NVIDIA Compute capability ≥ 3.0
Compatible with:
• NVIDIA Jetson Nano
• NVIDIA Jetson TX2
• NVIDIA Jetson Xavier
Output Data Rate 50 Hz
Barometer
Pressure Range 300 to 1100 hPa
Pressure Resolution 0.18 Pa
Relative Pressure Accuracy 0.12 hPa
RMS Noise 0.2 Pa
Output Data Rate 25 Hz
Temperature Sensors
Temperature Range -40 to 125 °C
Abs. Temperature Accuracy +/- 0.5 °C
Output Data Rate 25 Hz
Rev 1 specifications are subject to change without notice - 2019 - All rights reserved.
www.stereolabs.com
Page 4
ZED 2
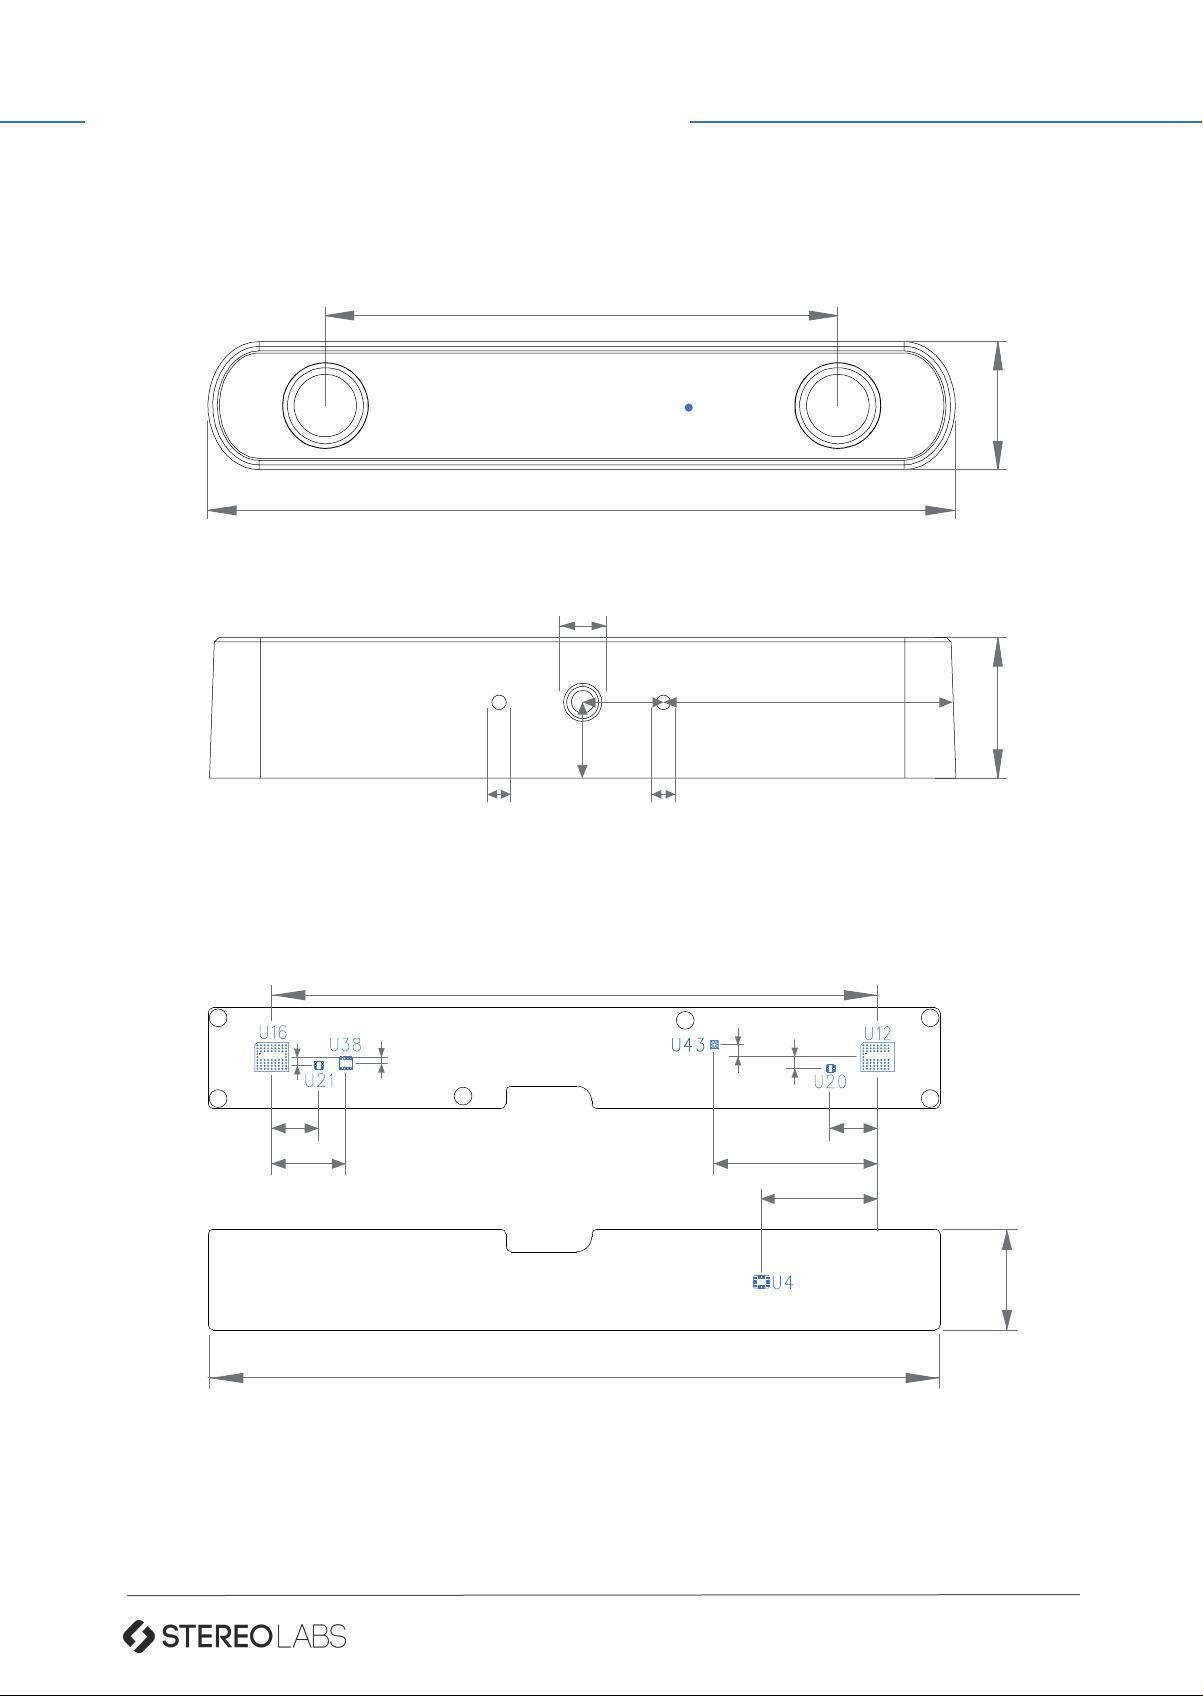
Mechanical Drawing
Dimensions are in mm
120
Sensors Diagram
175
1/4”- 20 Thread
18.4
17.1
M3 Thread
120
ZED
30
57.5
33
Front
Back
1.6
9.3
14.6
U4 IMU - Accelerometer Gyroscope U21 Temperature Sensor Right
U12 Image Sensor Left U38 Barometer
U16 Image Sensor Right U43 Magnetometer
U20 Temperature Sensor Left
1.2
145
2.5
2.2
32.3
23
9.4
20
Rev 1 specifications are subject to change without notice - 2019 - All rights reserved.
www.stereolabs.com
 Loading...