

Page 1
Autopilot – User's manual
Electrical connection
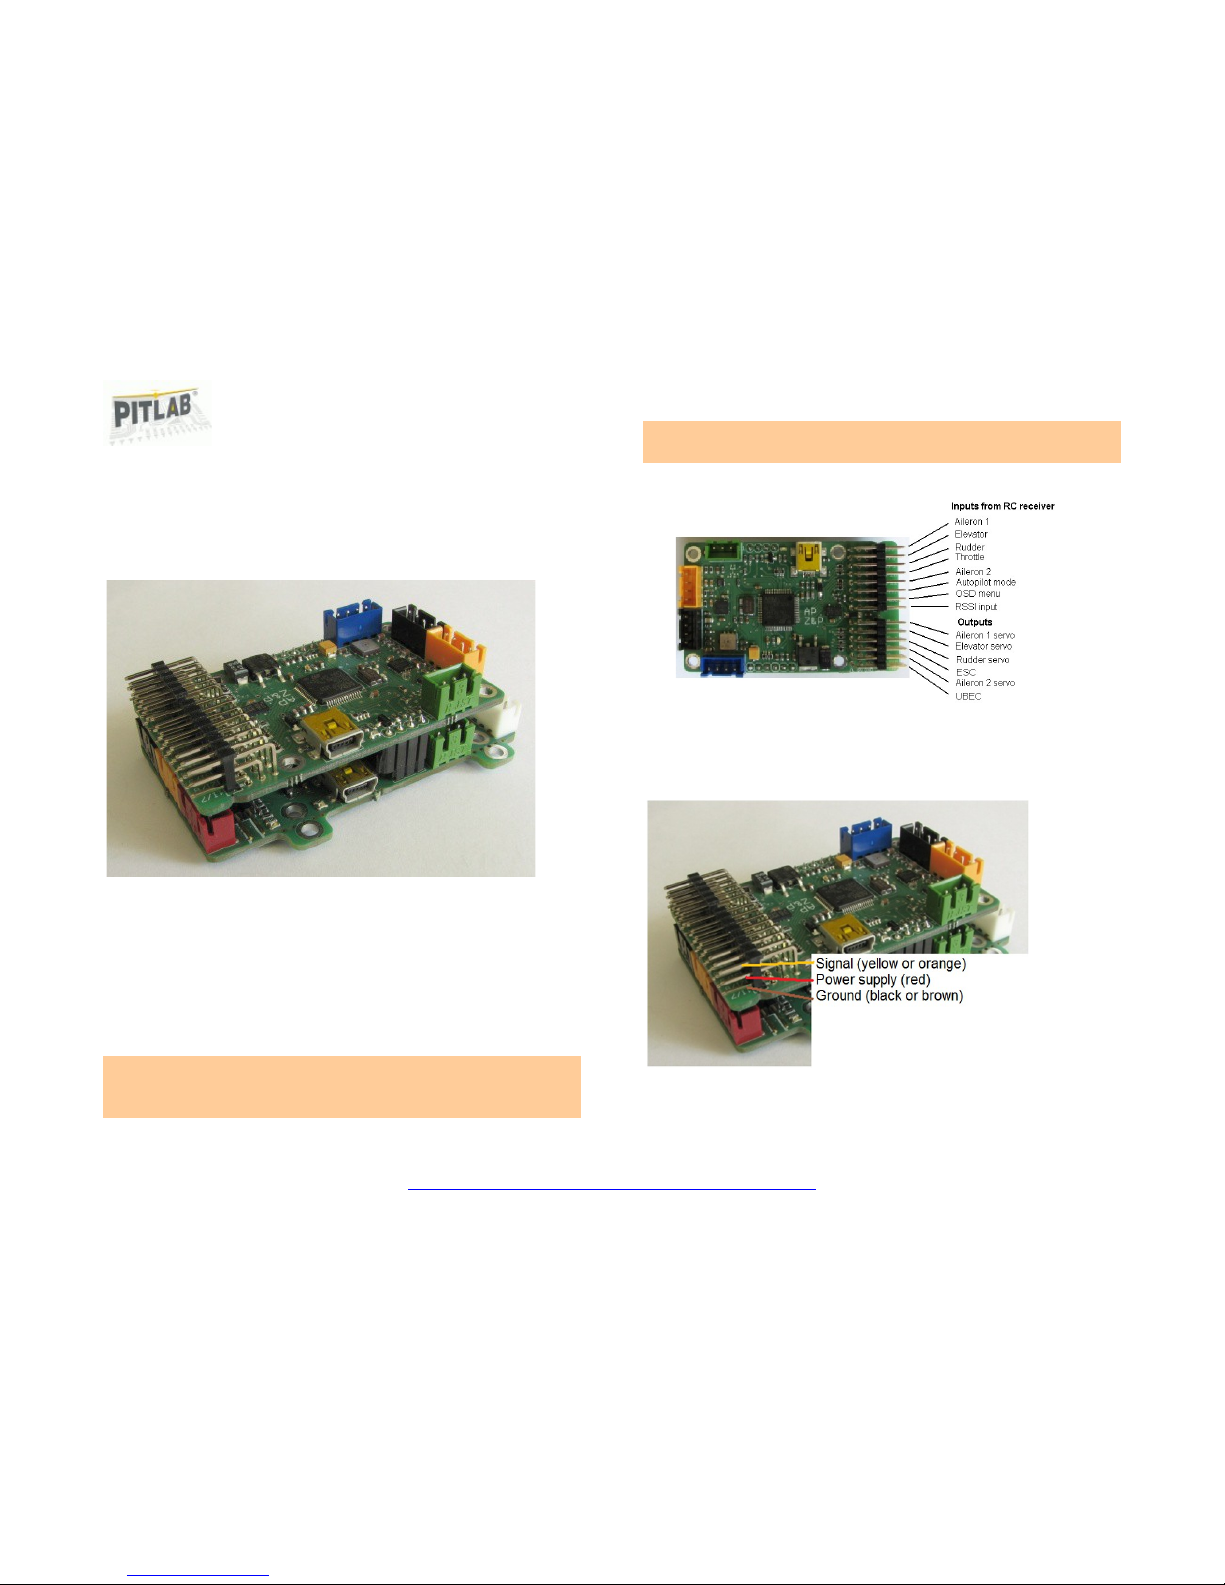
Autopilot works exclusively in combination with the OSD. All electrical
connections between the OSD and autopilot PCBs are made through a
dedicated connector on both PCBs. When purchasing a set, the two units
are electrically and mechanically connected to each other.
Autopilot can be connected to a remote control in two ways, depending
on the characteristics of the receiver and the autopilot settings.
Parallel connection of the receiver
Remote control receivers with autonomous outputs of all signals
(parallel) are connected with the autopilot in such a way that the outputs
of appropriate channels of the receiver are connected with the
corresponding input channels of the Autopilot.
NOTE: The remote control kits from different manufacturers may have
different signal sequence-for specific control elements (ailerons, gas,
direction, altitude), so connecting further signals to the autopilot, you
should pay attention to the meaning of the output from the receiver and
inputs of the autopilot.
The receiver should be connected to all the control signals, and at least
one ground and power supply wire (it is not necessary to connect all pins
of the ground and the power supply). The autopilot should also be
connected to the RSSI signal if the receiver is equipped with such output.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 1 of 21
Page 2
Autopilot – User's manual
Serial connection of the receiver CPPM or S-Bus
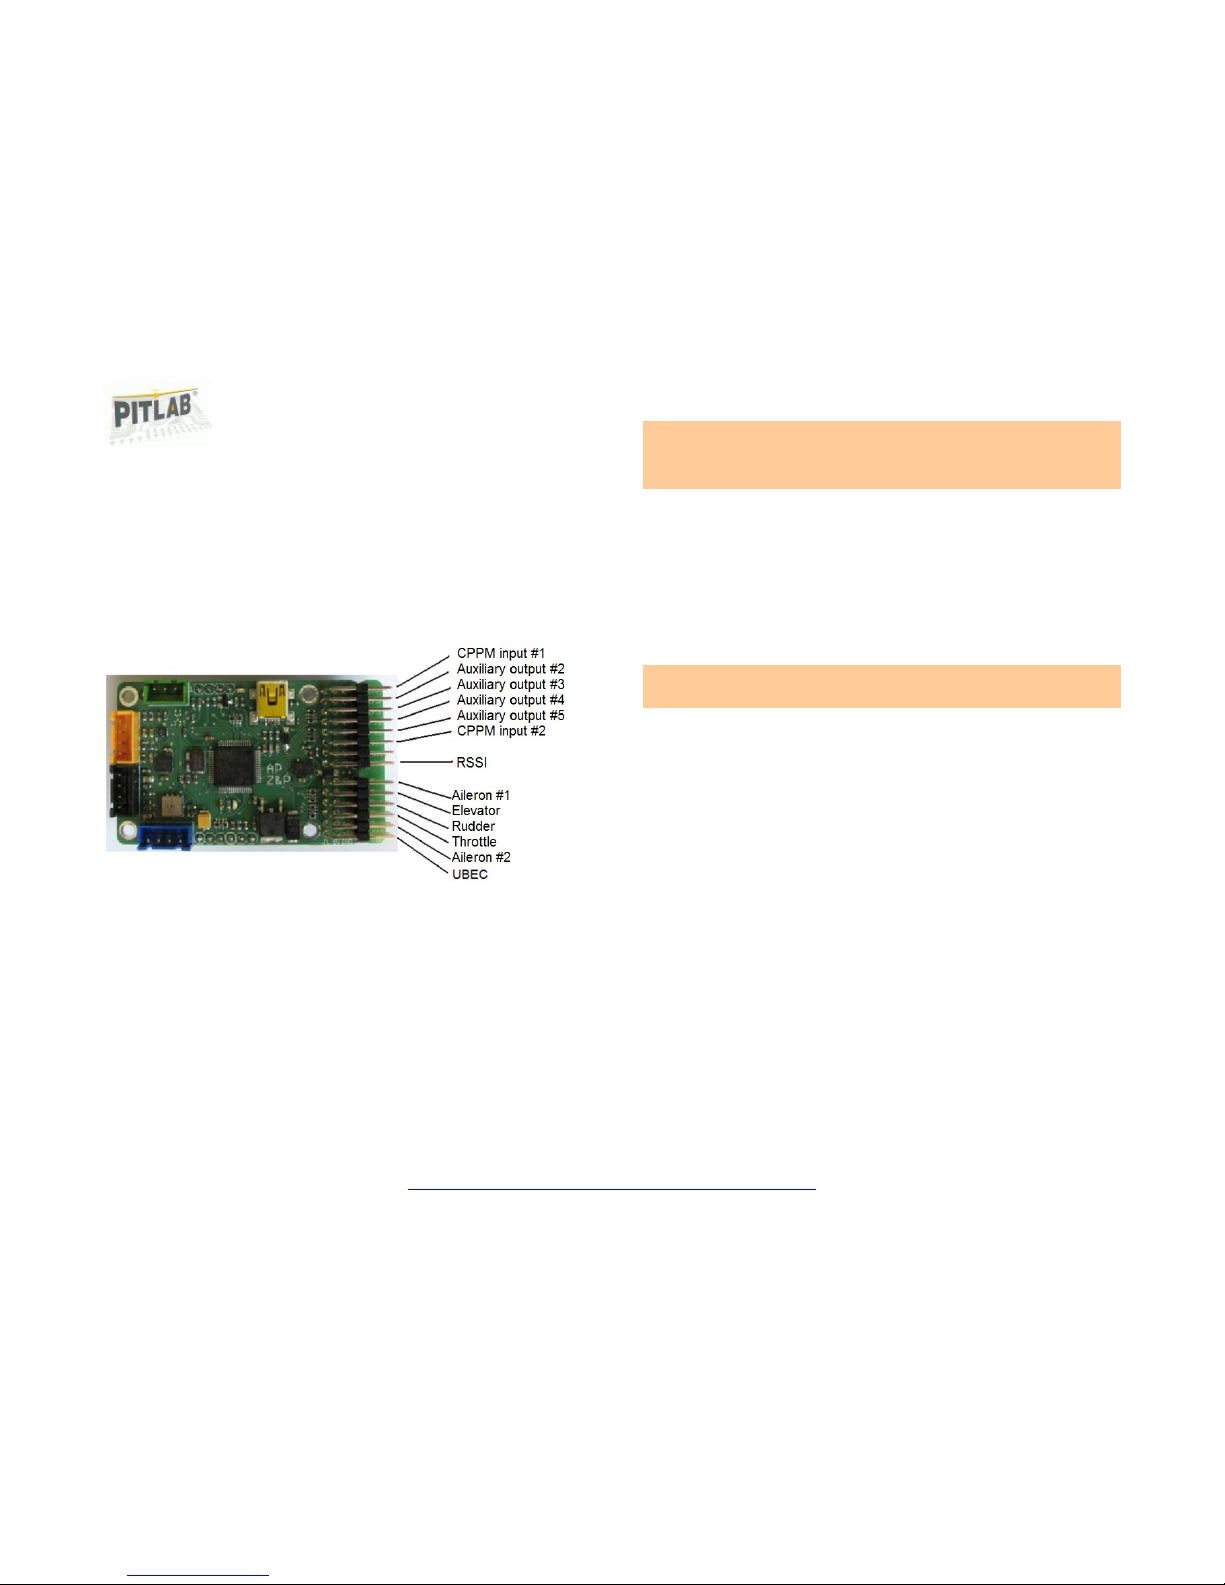
If you use a receiver equipped with serial PPM output (CPPM) or S-Bus,
connection of all channels to the autopilot can be made by a single signal
cable. In this case, we connect to the receiver a ground pin, power, CPPM
or S-Bus and RSSI signal if the receiver is equipped with such output.
If you connect Serial PPM signal (CPPM / S-Bus), it is necessary to set up
this signal with FPV_manager applications on your PC. Please connect
autopilot board to the computer (via USB) and in configuration
application, choose the socket pin of the Serial Input PPM (CPPM) - Input
#1 or #6 or S-Bus on input #1, and make an assignment of the other
channels of signal to each function of the autopilot.
In serial mode, you can configure the unused PPM inputs as outputs of
autopilot additional channels from serial signal (output Aux 2 to Aux 5).
This eliminates the need to purchase an additional CPPM/S-Bus decoder.
NOTE: Additional Aux 4 and Aux 5 outputs offer additional filtering and
option for simple gimbal control and are recommended for the control
of a pan-tilt system (camera control)
RC signal diversity
To avoid problem with RC link on long distances the both serial inputs
can be supplied by 2 independent RC receivers working as diversity.
Receivers can work in CPPM (on both #1 and #6 input channels) or SBus mode (on #1 input channel). To work properly both receivers
should have the same channel order.
Document: Detailed description of diversity is described in separate
document: “Diversity in PitLab FPV System”.
Connecting the servos and motor controller
Autopilot directly controls servos in the model, and the electric motor
speed controller (ESC). These devices must be connected to the
appropriate terminals, according to their description.
Because the autopilot in stabilization and AUTO mode actively stabilizes
the position of the model in response, among others to wind gusts or
turbulence, it more intensively burdens the servos and makes them
consume significantly more power during operation. Normally used linear
voltage regulators built in motor speed controllers often are insufficiently
efficient to meet the increased demand of current and are subject to
overheating, which can lead to a malfunction of the system. For this
reason, we recommend the use of external switching controllers (UBEC)
rated for 3A or more (depending on the size of the model), or motor
controllers with built-in switching UBEC. In the case of external UBEC
please disconnect the red wire from the plug of motor controller.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 2 of 21
Page 3
Autopilot – User's manual
GPS Connection
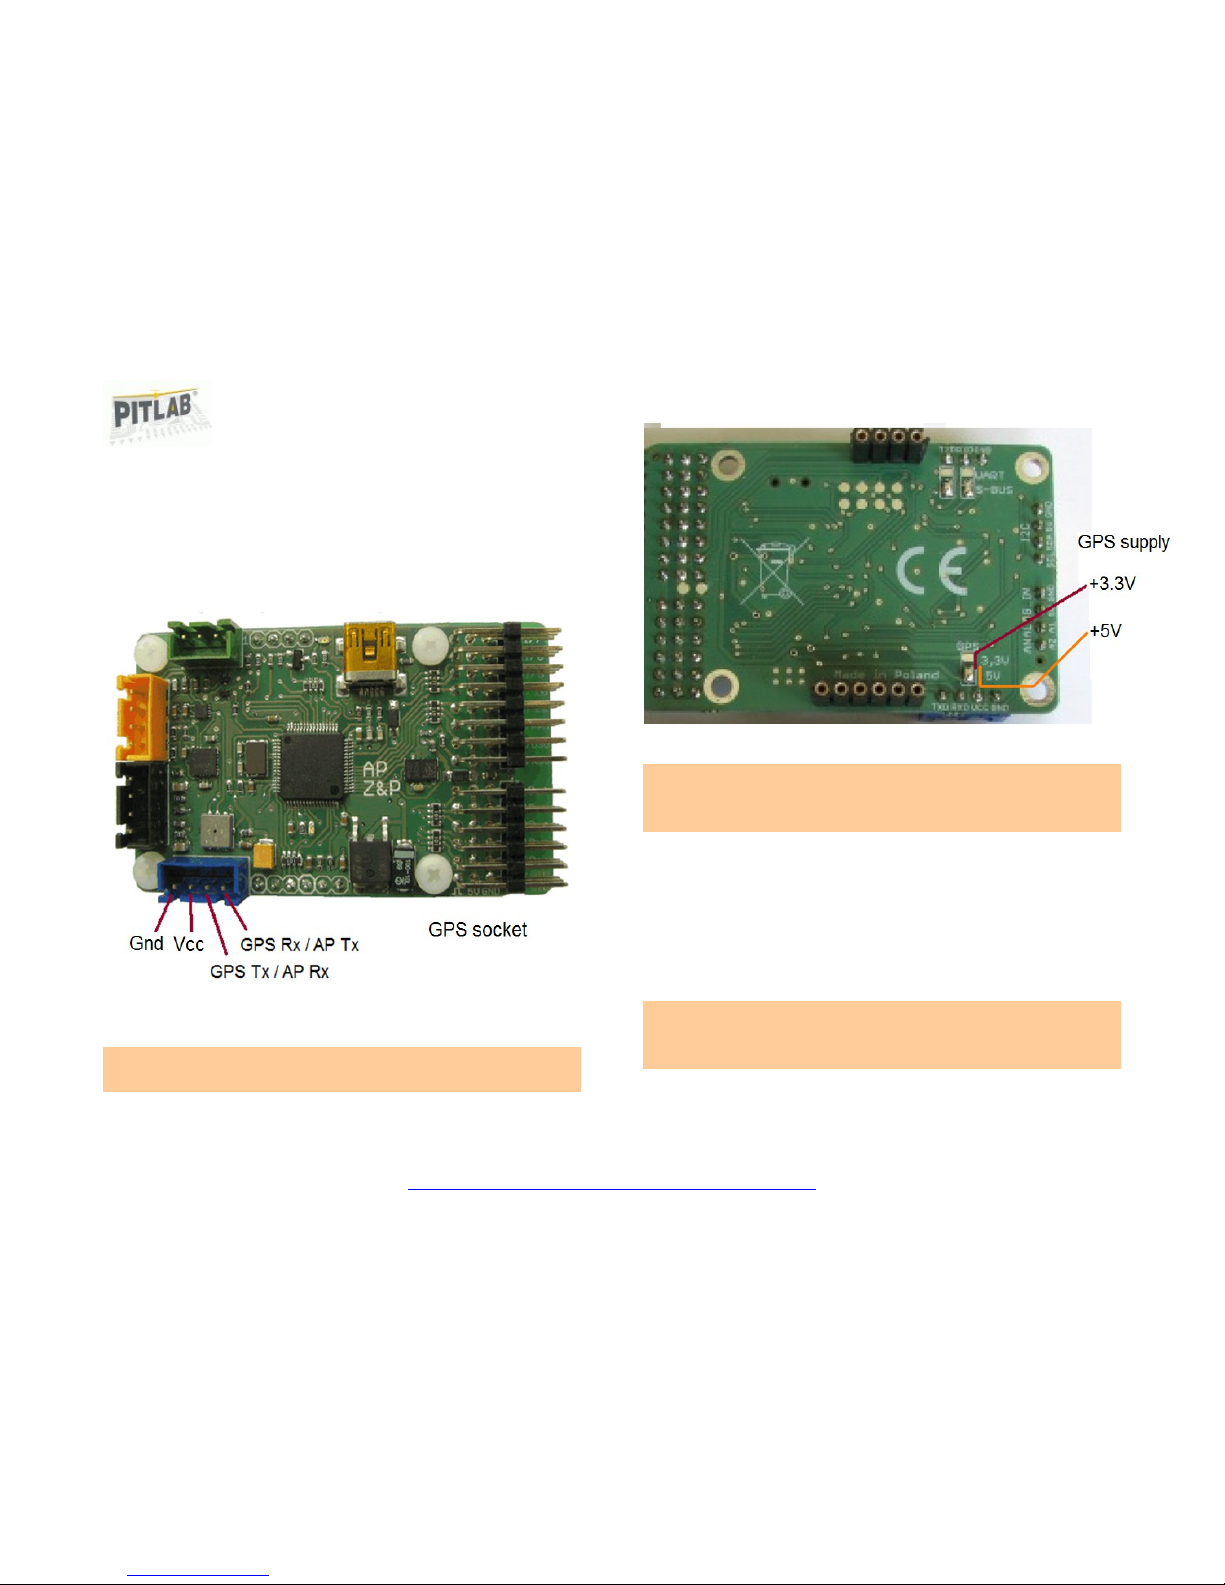
Using the OSD -Autopilot set it is advisable to switch the GPS connector
from the OSD board into connector on autopilot PCB. In such case the
GPS system is supplied by a pulse-UBEC (like servos), relieving the linear
regulator circuit on OSD (less heat is generated on the OSD board), and
reducing the power consumption of the video set.
If you use your own GPS, connect it to the connector as described.
NOTE: Before you connect your GPS to the autopilot board you must
verify and possibly change the value of the GPS supply voltage.
The changes are made by soldering respective fields with a drop of tin.
NOTE: This option may be changed only for 3-rd party GPS module. The
default GPS voltage setting corresponds to GPSs available in the store
and sold in a set, in this case no power supply voltage change is required.
RSSI
Autopilot does not use the RSSI signal, but for the convenience of
connecting the receiver it has an input for connecting the signal to be
sent directly to the OSD board. Requirements for RSSI signal have been
escribed in the OSD manual.
NOTE: The OSD board in an earlier version (v2.1) does not receive an
RSSI signal from the autopilot, in such case the RSSI signal from the
receiver should be connected directly to the OSD terminal.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 3 of 21
Page 4
Autopilot – User's manual
Location of autopilot board inside a model
Autopilot has an integrated inertial unit (IMU), which allows to determine
the position of the autopilot board in three-dimensional space. This is a
bank and inclination plate (relative to the vertical - the force of gravity),
the direction the front of the plate is facing (compass direction), and the
altitude above the airport (on the basis of changes in barometric
pressure). Thanks to these properties, the autopilot can maintain (and
stabilize) the levels of model flight, and provide the OSD with information
of model tilt (artificial horizon).
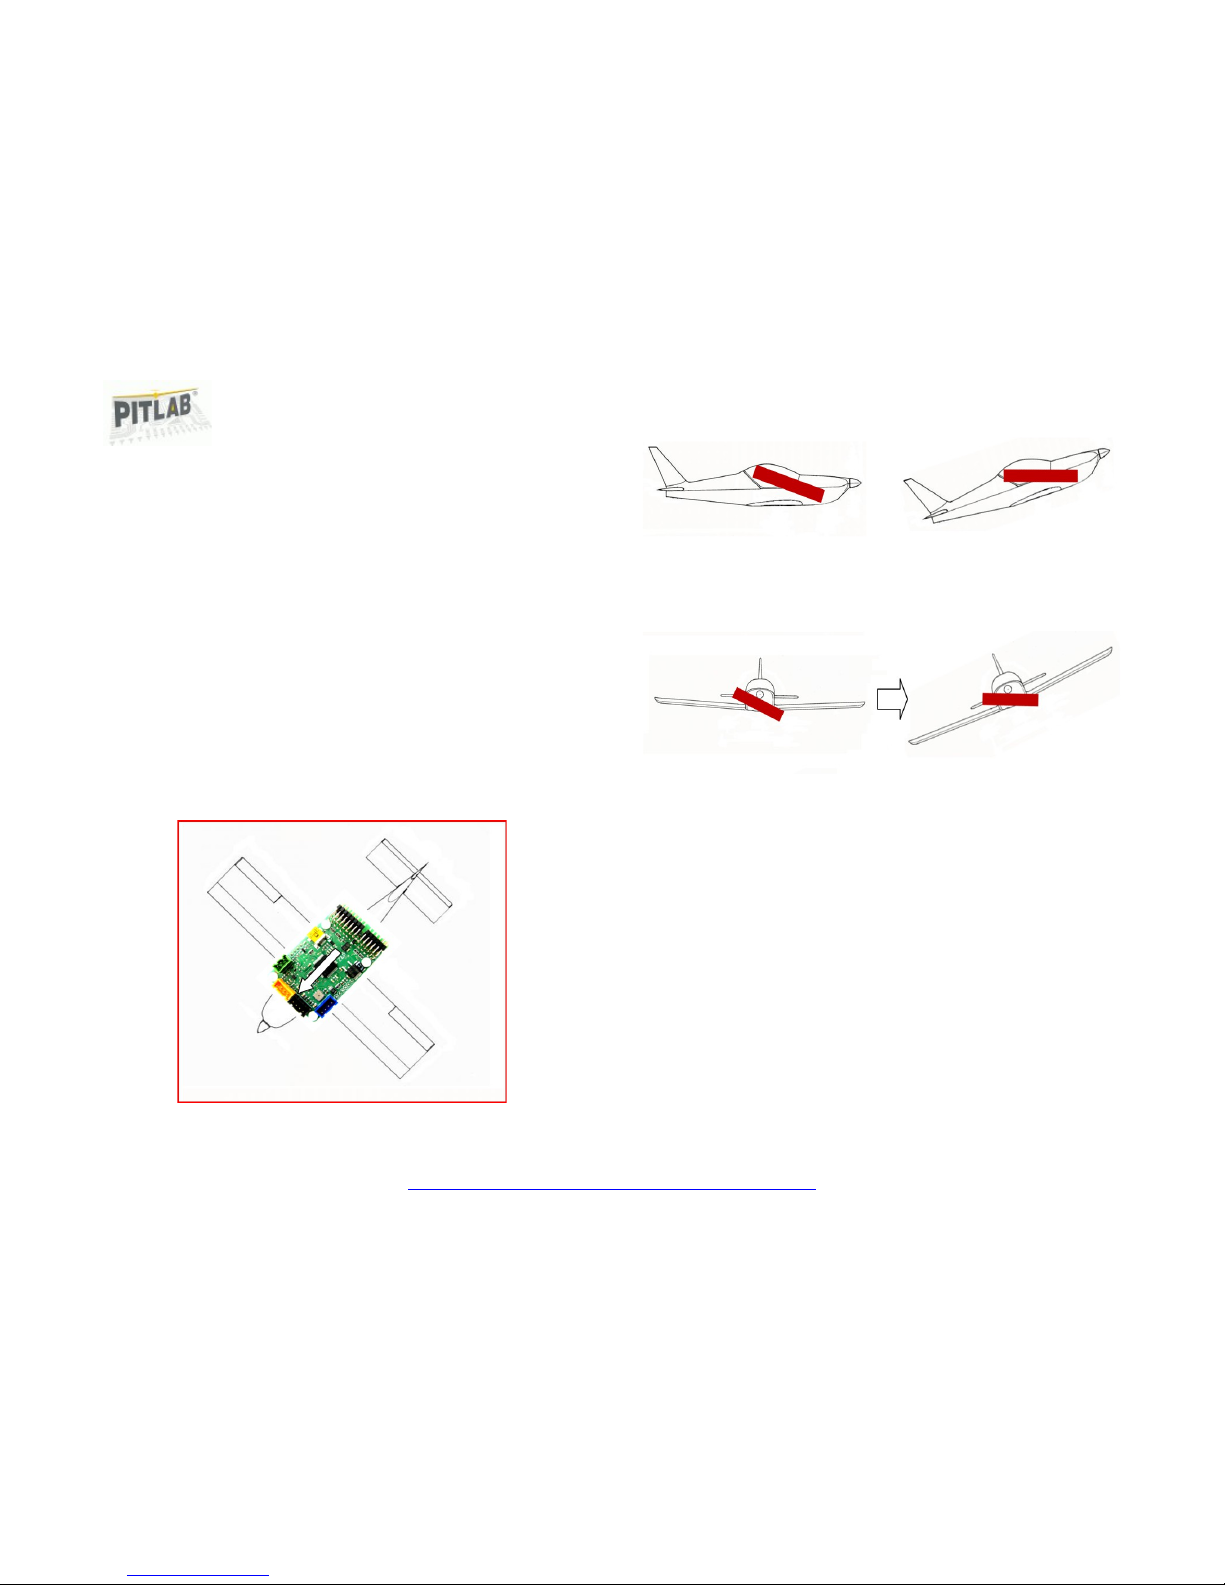
However, in order for the information about the location of autopilot
board to agree with the current position of the model, the autopilot
board should be mounted in a suitable manner in a model, so that at the
fixed level flight of the model, the autopilot board was horizontally facing
the direction of flight.
Figure 1 Correct locations of the autopilot inside the model
Figure 2 Impact of incorrect autopilot location on model flight
Figure 3 Impact of incorrect autopilot location on model flight
Small by few degrees autopilot position deviation can be compensated by
settings OSD by the horizon tilt (compensation may also be made during
the flight). Perfect location (or perfect compensation) occurs when
properly trimmed, models flying straight and horizontal in autopilot OFF
mode when you turn stabilization does not change the position a
noticeably.
Autopilot board does not have to be fixed exactly in the model’s center of
gravity, we can choose other convenient place in the hull of the model.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 4 of 21
Page 5
Autopilot – User's manual
Vibration protection
Autopilot should be protected against vibration (which affects the
position sensors: accelerometers and gyroscopes). You can use the
dumpers, sponge, or some other own patents. Dampers should dampen
vibrations and resonances (do not use springs and rubber).
NOTE: The greater the mass of an isolated element, the vibrations are
more effectively limited, so it is best to mount flexibly the whole
"sandwich" OSD + autopilot, and not the autopilot board only.
The vibration level is checked with the engine running - if overload and
vibration exceed 2g a digit will appear on the screen showing the current
number of overload (2g, 3g, up to 8g).
Excessive vibration causes tilting ("passing out") of the artificial horizon
on the OSD, despite the fact that the model is still level. The sensors, and
algorithms of the autopilot should ensure the proper operation of up to
the overload of 5 g, but keep in mind that during the fly, there are
additional overloads (turbulence, the centrifugal force, etc.), and
generally the lower the vibration, the more accurate is the work of the
autopilot. You must therefore strive to achieve a minimum level of
vibration from the engine.
Reverses and servos concurrency
Adjusting RC apparatus for controlling a particular model means to
correctly set reverses and mixers so that the control rods tilt correspond
to the appropriate control surface deflection. In the same way it is
necessary to adjust the autopilot to the specific model to ensure proper
control of autonomous flight model.
The first step is to select the type of model tail in OSD menu autopilot ->
Mixer
When one rod is attached to two servos and two control surfaces (delta,
tail V, flaperons), we can choose between two options of servos
concurrency, (in line) and (anti in line), depending on whether for the
proper control the opposite – or non-opposite movement of servos is
required.
In the second step, for each side of the rudder we set the correct channel
under OSD autopilot -> Mixers
Check the proper settings for servo and reverse concurrency after
stabilization mode is off, observing the behavior of the control surfaces
on bank and inclination of the model. When reverses and concurrency
are positioned properly, by tilting or pitching the model they must be set
in such a position that during the flight they counteract such deviation of
the model.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 5 of 21
Page 6
Autopilot – User's manual
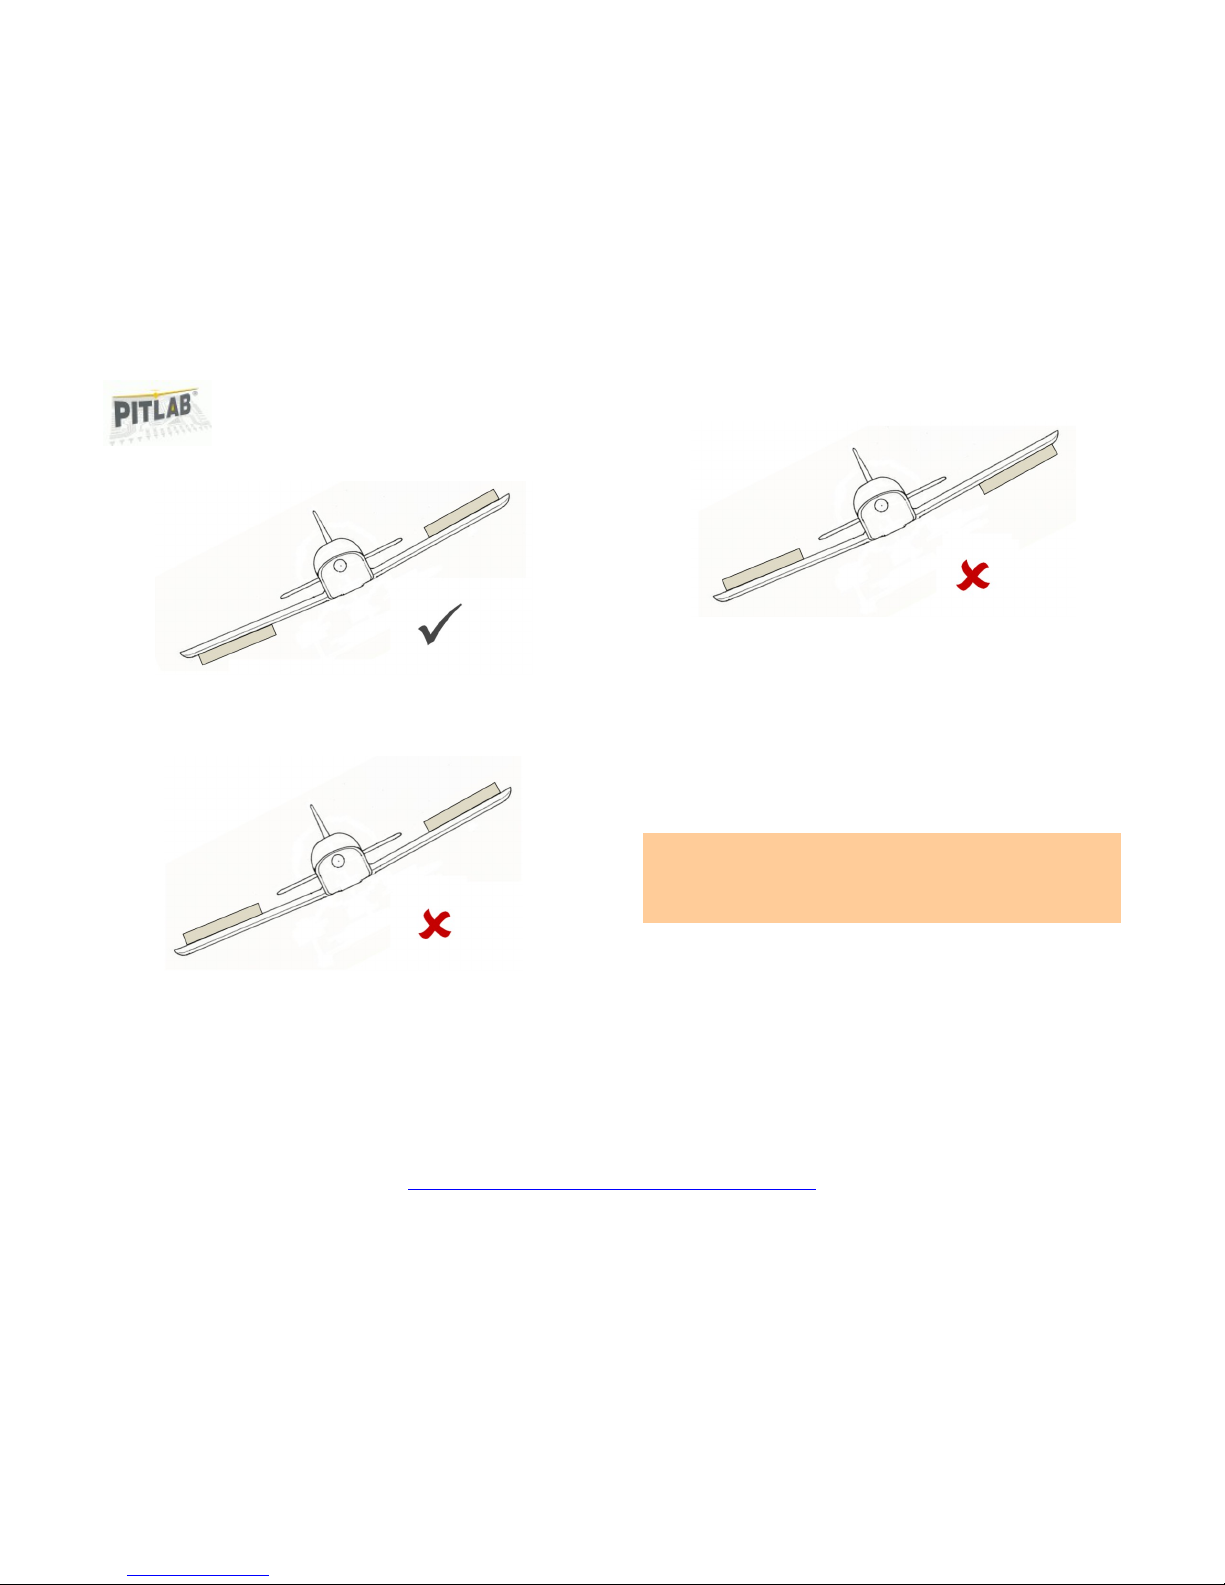
Figure 4 The correct setting of concurrency and servos reverses
Figure 5 incorrectly set servos concurrency
Figure 6 Incorrect setting of the reverse (correct concurrency setting)
Since the rudder does not participate in the stabilization of flight, it is not
possible to set its reverse on the basis of observation of the behavior of
the model at tilts. Therefore, after any change to reverse of the rudder
the autopilot for about 1 second swings the rudder like to turn to the
right. If after the change of the reverse you see the rudder turn left, it
means that the reverse is not valid.
NOTE: As of version 2.13 of OSD firmware it is more convenient way to
set the reverse of the rudder when selecting the appropriate option in
the OSD menu and deflection in the transmitter of rudder rod to the
right.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 6 of 21
Page 7
Autopilot – User's manual
Autopilot modes
Autopilot mode control is done by a three-state RC channel connected to
the PPM "6" output, as follows:
Channel for minimum (PPM pulse duration less than 1.2 ms): OFF
- autopilot off.
The center-channel (pulse duration 1.3 ms to 1.7 ms): STAB -
stabilization mode
Channel for maximum (pulse duration more than 1.8 ms): AUTO -
autonomous flight
Furthermore, in the autonomous flight mode you can select one of the
three throttle control position:
Gas at a minimum: AUTO - back to the starting point.
Gas in the middle: WP - flight on waypoints along the route (a
more detailed description contained later in this manual)
Gas to maximum: (*) - circulation over the current GPS point.
Current autopilot mode is indicated on the OSD screen next to the pilot
icon.
In order or the model to automatically return to the starting point if you
have problems with a range of RC circuit, FailSafe mode must be correctly
set in the RC receiver :
duty cycle of operation mode channel to maximum (AUTO)
duty cycle of gas at minimum (back to the starting point).
Document: The development of FPV System made to increase
number of sub-modes. Detailed description of all sub-modes is in
separate document: “Navigation modes in the Pitlab & Zbig FPV
System”.
Turning the autopilot off
In the OFF mode, all RC input signals are transmitted to the output
without any interference (except for disregarding false PPM pulse outside
the acceptable range of 0.8 ms to 2.3 ms).
If the autopilot is connected to only one aileron signal (input # 1 "aileron
1"), the autopilot transmits the same signal on both ailerons outputs works as a "Y" cable, making it easy to control two servos from one RC
channel.
Stabilization of model
Stabilization of model is essential in order to prevent unexpected or
uncontrolled changes of model position. Proper configuration of
stabilization mode is also required for the correct operation of
autonomous flight mode.
In the case of model deviations from the desired position, stabilization
system forces appropriate control surface deflection to eliminate these
deviations. Proportionality of steering surfaces deflection in relation to
the position deviation is defined by setting in the OSD menu Autopilot>Roll stabilization and Autopilot->Pitch stabilization.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 7 of 21
Page 8
Autopilot – User's manual
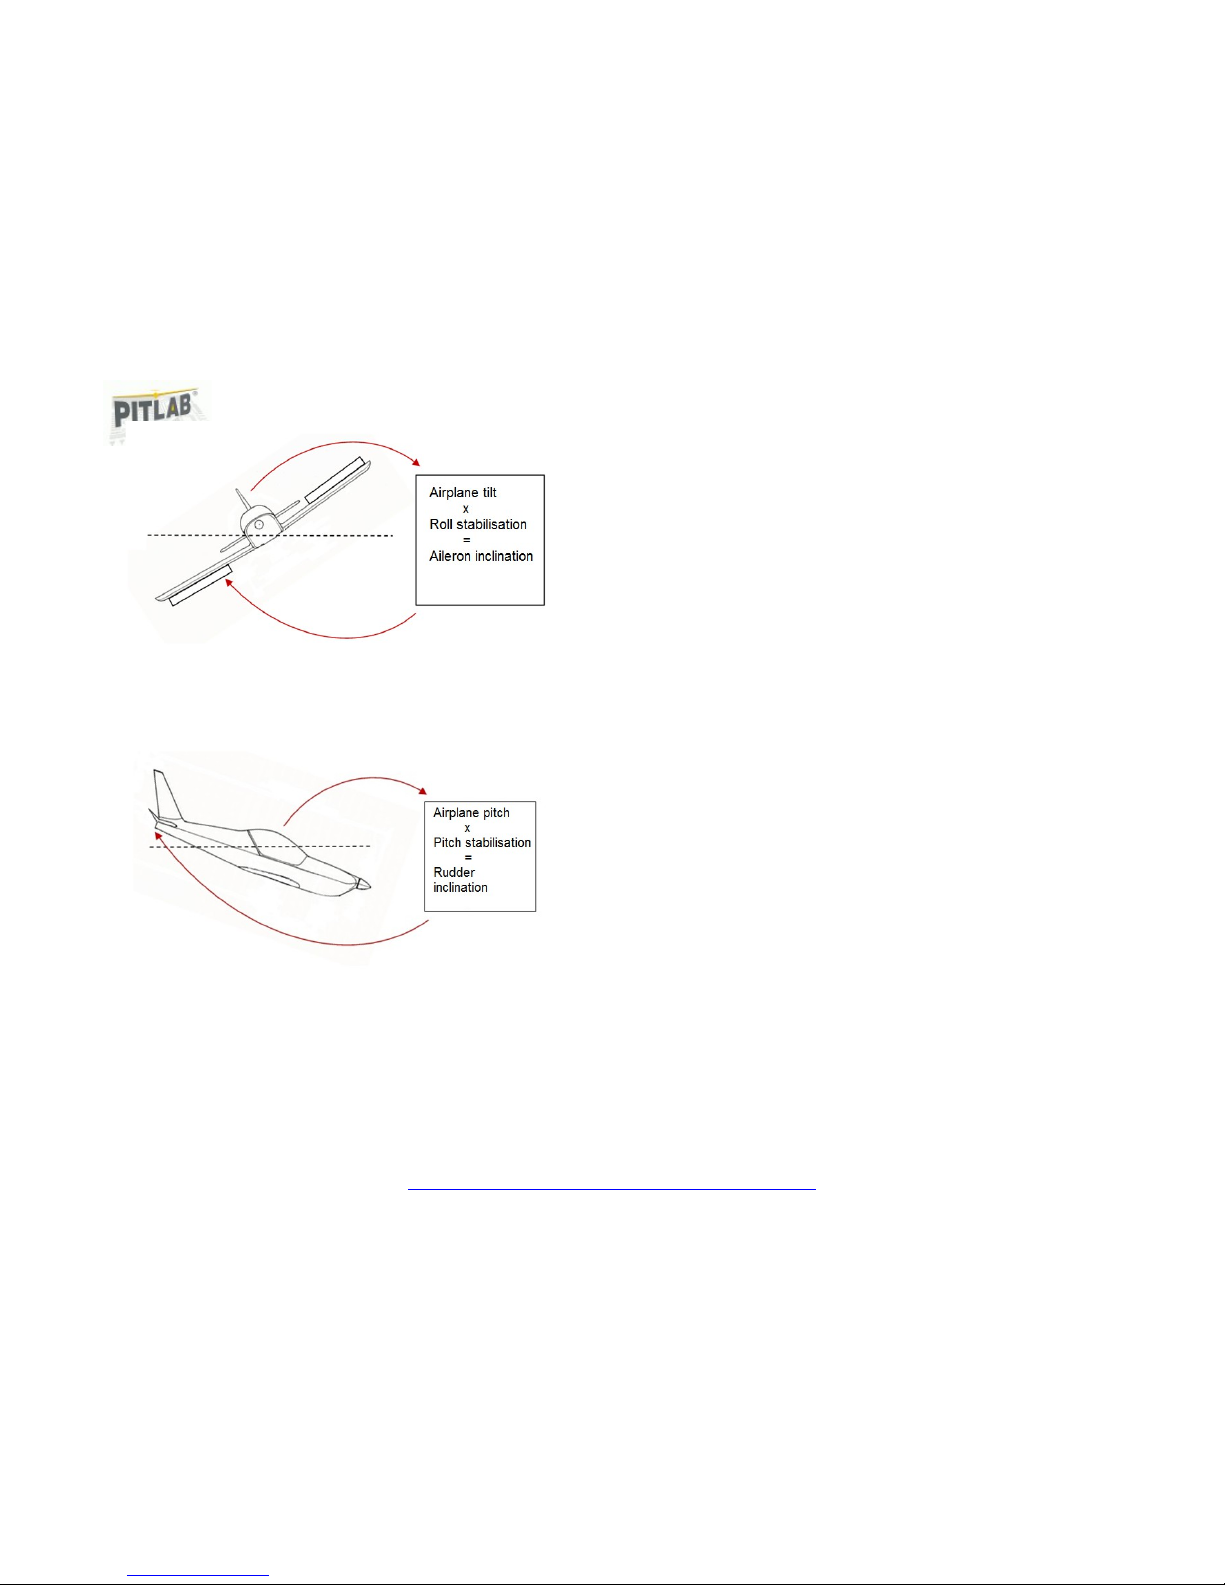
Figure 7 Illustration of operation of banking stabilization algorithm
Figure 7 Illustration of operation of inclination stabilization algorithm
The correct setting of the stabilization of the model is necessary to work
in autonomous mode of the autopilot.
We set the highest value of the roll stabilization force at which the model
is flying steadily without falling into oscillation. Too high stabilization
value is manifested by rapid fluctuations in the wings - especially with
increasing speed.
Too low roll stabilization force could prevent proper flight in AUTO mode
(unstable flight, too small or too great banking of model during turns)
We choose the mean pitch stabilization force, with which the model
aimed sharply down, after releasing the elevator stick gets back to the
level without pumping , and cutting the gas airplane glides without
deceleration and stall, and after the addition of gas attains altitude, but
also does not take up too hard.
Small values of pitch stability may cause pumping of the model and with
the model with a strong drive too rapid pulling up of the model on gas.
Too high pitch stabilization force can cause quick, short oscillating up and
down, especially at higher speeds, and also cause stall of the model
without gas, and poor ascending on gas (model accelerates, without
ascending), causing problems in autonomous flight.
Autopilot in stabilization mode does not hold directly the setpoint
direction of flight, but by keeping the level of the model largely
eliminates the unplanned deviations from the current model course.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 8 of 21
Page 9
Autopilot – User's manual
Autonomous flight mode
In autonomous mode, the autopilot controls the model flight alone,
maintaining the right direction and altitude, as well as preventing too
rapid model banking, which could cause loss of control (framing the wing,
corkscrew, etc.).
In autonomous mode, the autopilot is flying to the point specified by the
position of the throttle (gas channel modulation). Also the distance and
the course displayed on the OSD are always relative to the currently
selected destination (base, waypoint or point of circulation).
Gas at a minimum: AUTO - back to the starting point.
Gas in the middle: WP n - flight to the route number 'n'.
Gas to maximum: (*) - circulation over the current GPS point.
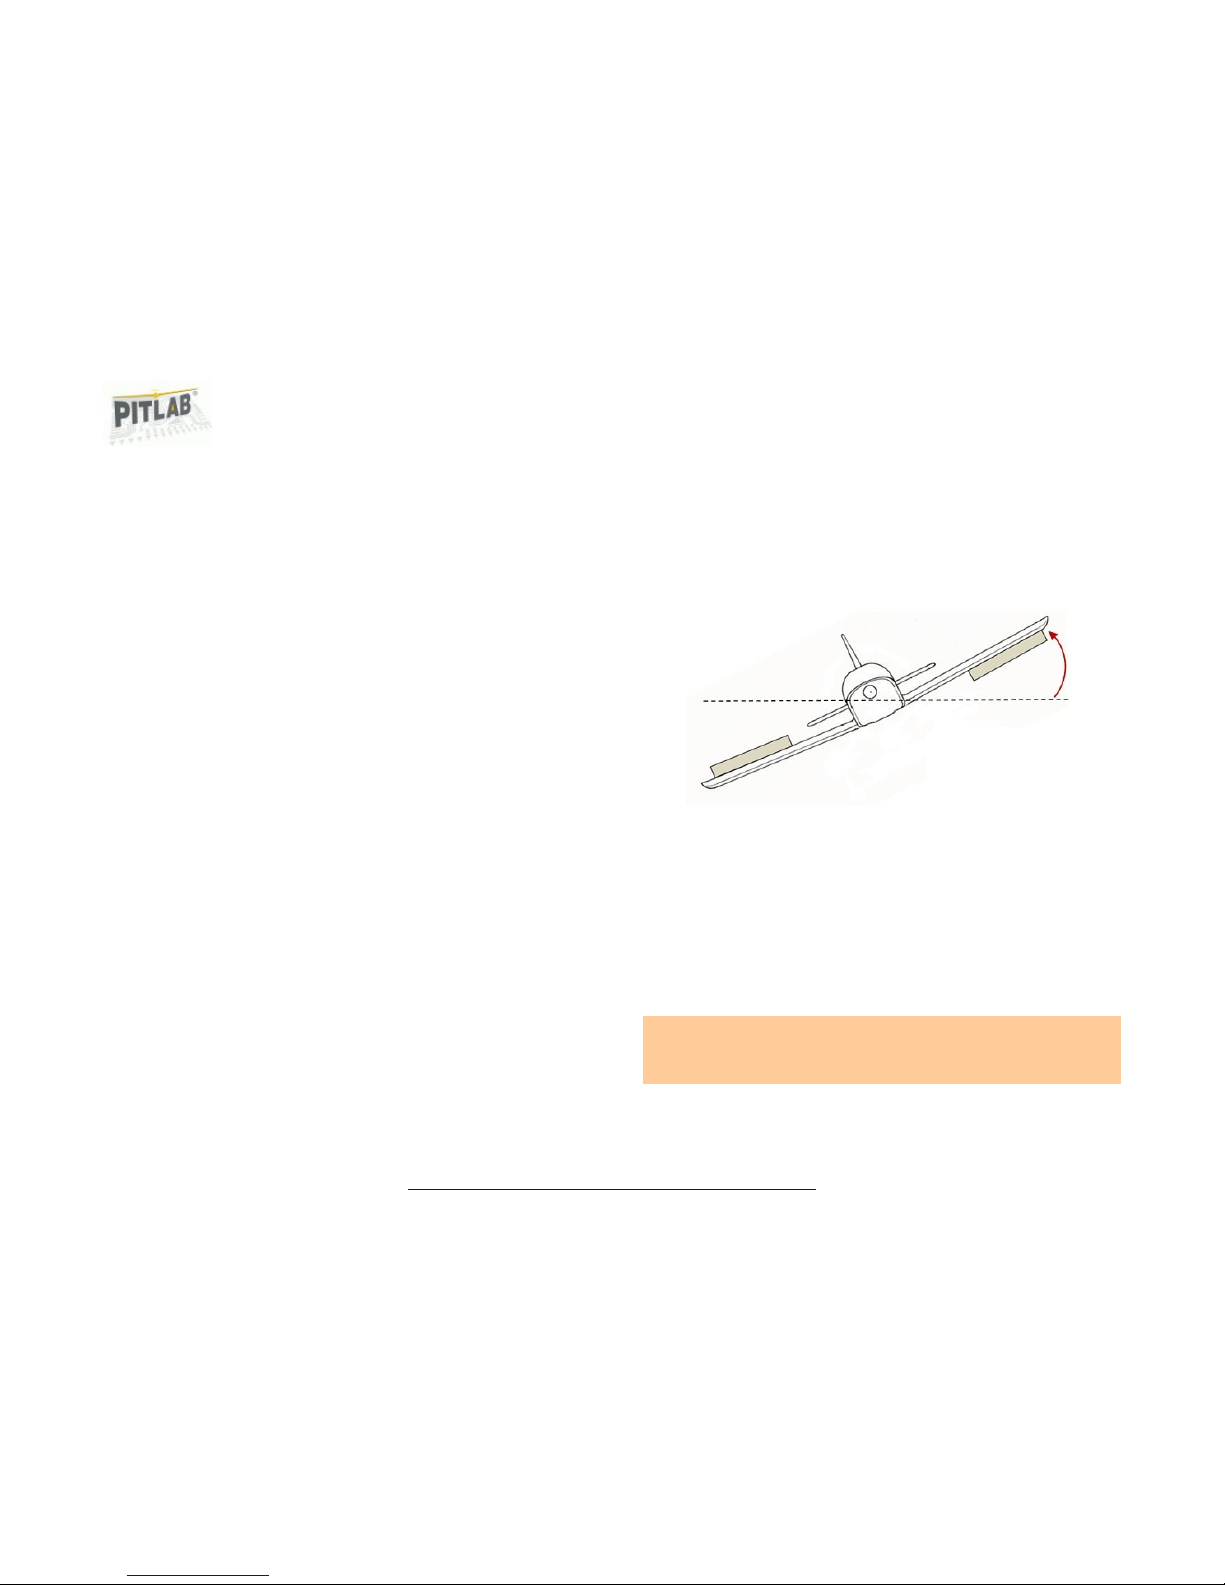
Banking limit
In order to maintain control over the model it is necessary to determine
the maximum (and safe) allowed model banking during maneuvers in
autonomous mode. Make the settings in the OSD Autopilot-> Banking
Limit
Figure 9 Maximum banking of the model in autonomous flight
Too small value of the maximum banking increase the turn radius, or may
even prevent it from turning in strong wind. Too large values can cause
problems with the stability of the model in the air can cause the loss of
altitude during the turn, and cause significant deviation (delay) of the
course provided by the GPS in relation to the real course of the model, so
the model when turning to the base and starts "poking" flying to the
base.
NOTE: For models with a large agility (large aileron deflections) or with
set lower stabilization force it may be necessary to adjust the lower limit
of the banking angles.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 9 of 21
Page 10
Autopilot – User's manual
Force of getting back on course
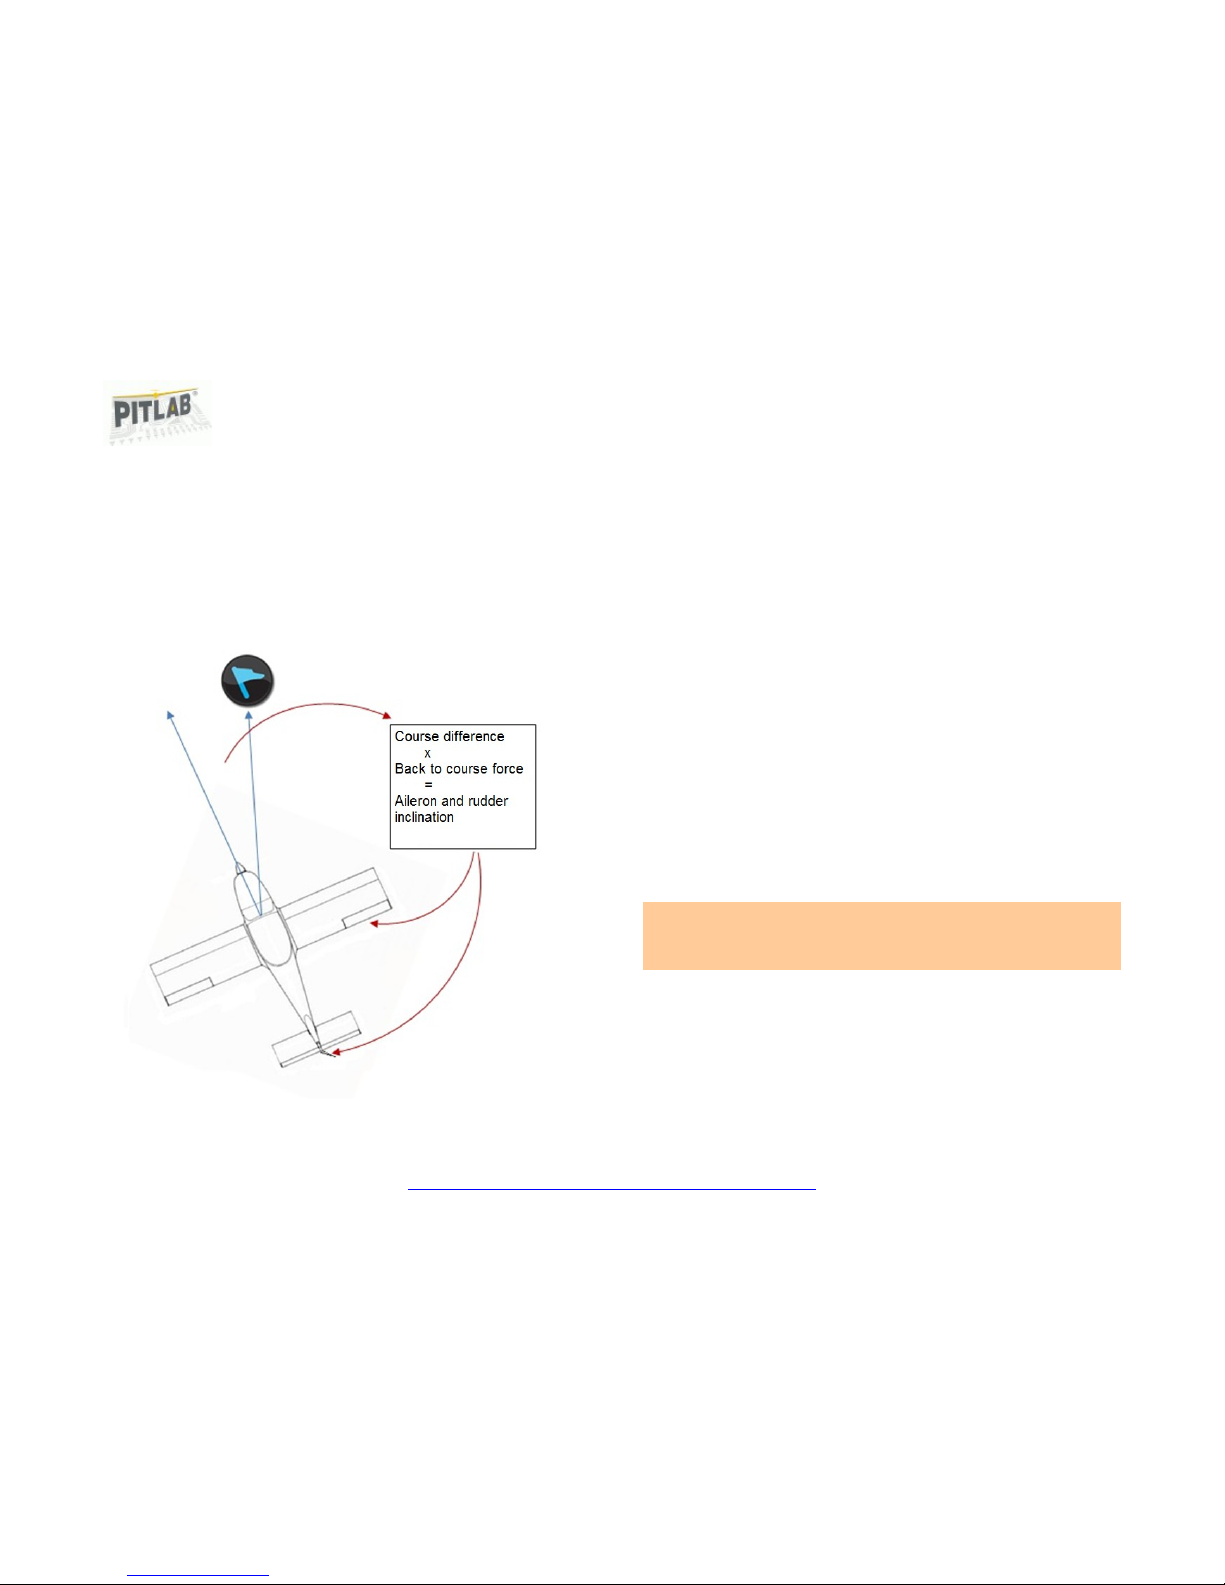
When in the autonomous fly the current course of the model is different
from the desired course to the base (or waypoint) the autopilot makes a
turning maneuver performed in order to return to the right course.
Accuracy of staying the course, and the deflection of the ailerons and
rudder in case of deviation from the course is defined by OSD parameter
Autopilot-> Force of getting back on course. This is illustrated in figure:
Figure 10 Illustration of the algorithm to maintain the course
The greater the deviation of the course, the stronger the swing of
ailerons and rudder causing getting back on course. This means that if
deviation of the course is high, then also the turning speed of the model
is high, and with getting closer to the expected course the speed of turn
decreases.
If this value is too low, the model will be turning slowly and will not be
coming to the course to the base. Too high a value causes the model to
perform a quick turn also when the deviation of the course is low, so that
the model significantly exceeds the course and oscillates around the
course flying zigzag.
Mixer ailerons-> direction
Turn of the model is generally obtained by ailerons, but it is also possible
to add steering with the rudder. This is done by the mixer set in the OSD
menu options Autopilot-> Mixers-> mixer ailerons- direction, that helps
to turn the model. In models with ailerons its use and value is at the
discretion of the pilot. Too large values of the mixing can cause excessive
model banking in relation to the value of the banking limit set in
autopilot menu.
NOTE: in aerobatic models where the ailerons do not turn the model, we
should set high values of aileron-direction mixer, and a small banking
value limit.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 10 of 21
Page 11
Autopilot – User's manual
The slowdown in turn
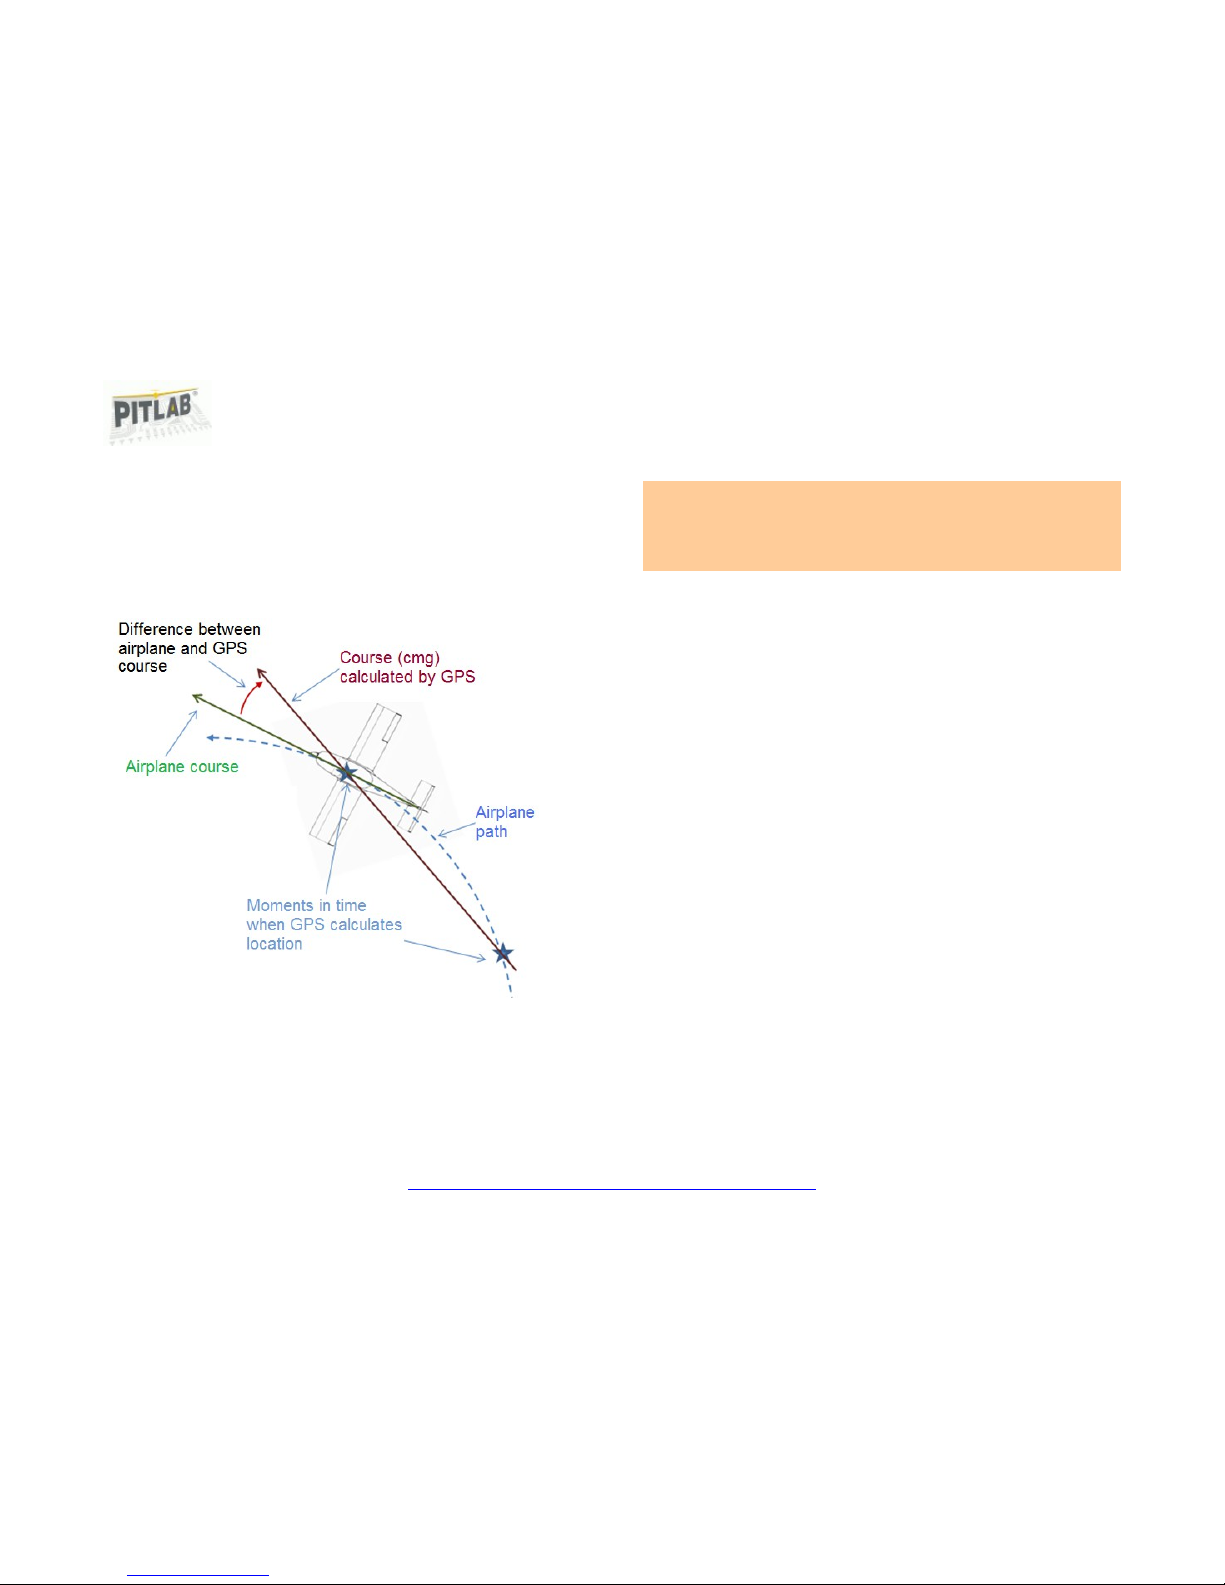
Since small values of the maximum model banking can cause problems in
the event of strong winds, it is necessary to use average values of the
banking limit, aided by dynamic constraint (slow down) of the turn speed,
which prevents problems with GPS course.
Figure 11 The error of indication of the course during a quick turn GPS
model
The slowdown in turn can be set in the OSD Autopilot-> turn slow-down.
NOTE: When using the magnetic heading it is not necessary to slow
down the bend more, as the used magnetometer has a sufficient speed
and precision of operation, even with a stronger heel and high-speed
turns.
Compensation of crosswinds
If some factor, such as crosswind (but also bad trimming or bad position
compensation of autopilot) causes the model is still relegated from the
course and does not pull to the course to the base, this error is constantly
monitored and if it does not disappear, the autopilot is steadily increasing
aileron deflection to compensate for this error. It takes a relatively long
time (up to several seconds or even longer) and makes systematic
"pulling" the autopilot to the correct course.
Compensation is selected at the discretion of pilot, keeping in mind that
too high a value may result in exceeding the line of the course by the
model and a slow return to the course (or zigzag flight or a slow change in
the course), because the adjustment changes slowly.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 11 of 21
Page 12
Autopilot – User's manual
Maintaining the altitude
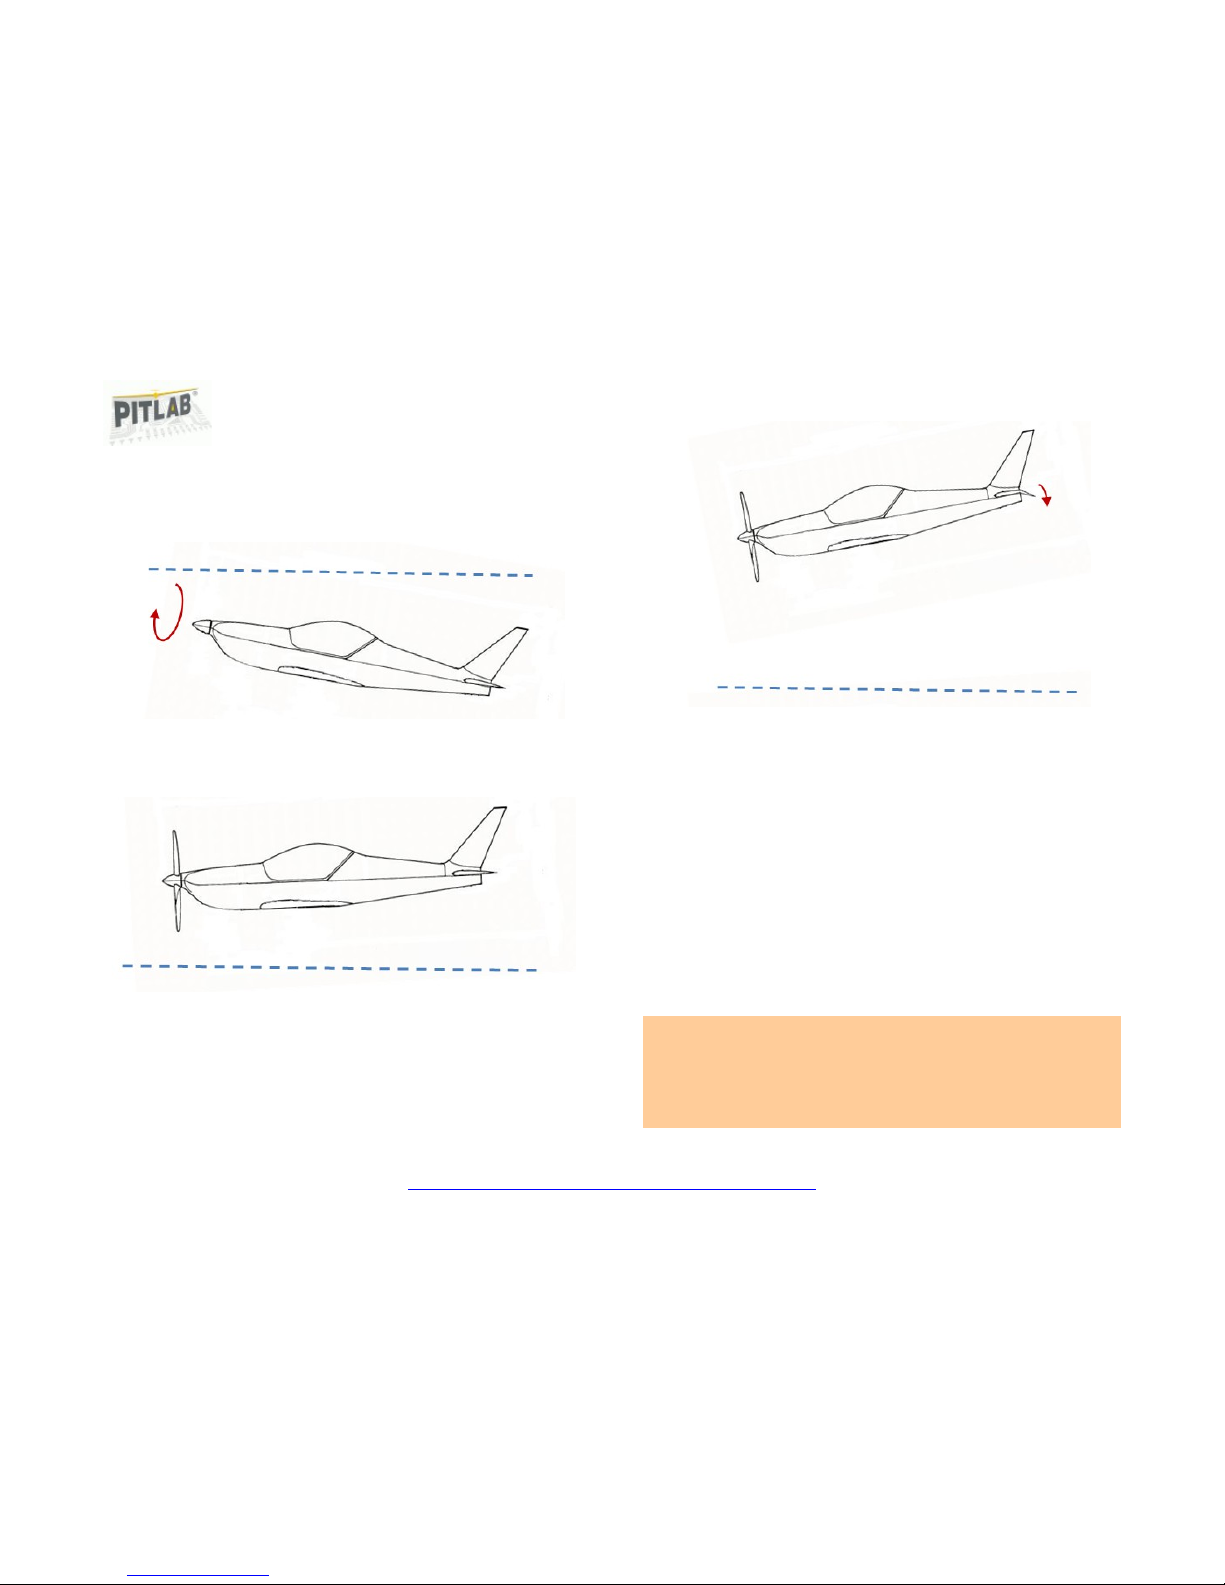
Maintaining the altitude of the autonomous flight is performed by gas,
so the model should ascend as the gas increases.
Figure 12 ascending of the model - engine flight
and the free fall of the model with the reduction (or shutdown) of gas.
Figure 13 Lowering the cruising altitude - free glide without engine
In certain situations, such as descent from a very high altitude and the
forced flight with much gas, autopilot also uses the elevator to lower the
altitude.
Figure 14 The use of the elevator during descent from a great altitude
Throttle limit
Throttle limit sets the maximum value of the throttle (power) which the
autopilot can use in AUTO mode. Reducing gas allows for a more
economical flight and limits the maximum cruise speed in models with a
strong drive, including the elimination of the risk of overheating the
motor or speed controller (ESC) during the autonomous flight after a long
tour. Too low limit may cause problems when flying in a strong wind.
Throttle limit must be sufficiently large to ensure that the ascent of the
model under adverse temperature conditions (such as "strangling" by the
downdraft).
NOTE: Saving the trim (OSD menu “Autopilot” -> “Save trims”) with tilted
gas rod can cause incorrect handling of gas by the autopilot (e.g.,
exceeding the set limit of gas). Writing a non-zero position of the gas is
needed for combustion models, allows you to save the position of rpm
speed (minimum) of the motor.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 12 of 21
Page 13
Autopilot – User's manual
Gas mode
Autopilot has three gas operating modes, allowing the autopilot to
customize the behavior to specific model and the modeler’s expectations.
On-off mode is designed to glider models. In this mode the motor is
switched on with the throttle level defined by the throttle limit
parameter and after attaining additional 50-70m the motor is cut off and
the model glides freely until the loss of altitude, whereupon the process
is repeated.
In Fixed throttle mode, the engine has constant throttle level
determined by the throttle limit parameter. This mode is recommended
when a fast return to base and fast performance of the flight route points
is required, particularly in strong or variable wind, and in models of poor
gliding, with a tendency to stall.
Dynamic mode is recommended for most models. In this mode, the
throttle is set to a value at which the model maintains a constant
altitude. This allows for the most economical flight of the model with a
moderate wind. In this mode the maximum value of the throttle used by
the autopilot is determined by the throttle limit parameter.
Cruising altitude
During autonomous return to base and circulation over the current GPS
point the autopilot maintains altitude at which the AUTO mode was
turned on.
During the autonomous flight along the points of the route, the autopilot
flies at an altitude given in the specification of each waypoint along the
route, or at the actual altitude (at the time of activation of the
autonomous mode) - If the definition of the route does not specify the
cruising altitude.
For autonomous flight we can specify the minimum and maximum
cruising altitude that guarantees safe flight. Setting of the cruising
altitude limit set in the OSD menu “Autopilot”-> “Altitude”:
Minimum altitude: If at the AUTO mode activation the current altitude of
the model is less than the specified value, the autopilot will rise model to
the preset minimum altitude and will continue to fly at that altitude. This
allows a return to the base at a safe altitude, for example, above the
trees or other obstructions.
NOTE: Disabling a minimum altitude allows for a flight at points along
the route below the starting point (e.g. when taking off from the hill)
Maximum altitude: If at the AUTO mode activation the current altitude
of the model is above the specified value, the autopilot will not maintain
this level, but will lower the flight by elevator and in dynamic throttle
mode the engine will not start until the model will reduce the flight to
the set maximum and then will continue to fly at this altitude (maintain
this altitude). This setting allows for the safe return of the model to an
area where it will be possible to regain lost range of the control RC, video
link or visual contact with the model.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 13 of 21
Page 14
Autopilot – User's manual
Minimum speed of the GPS
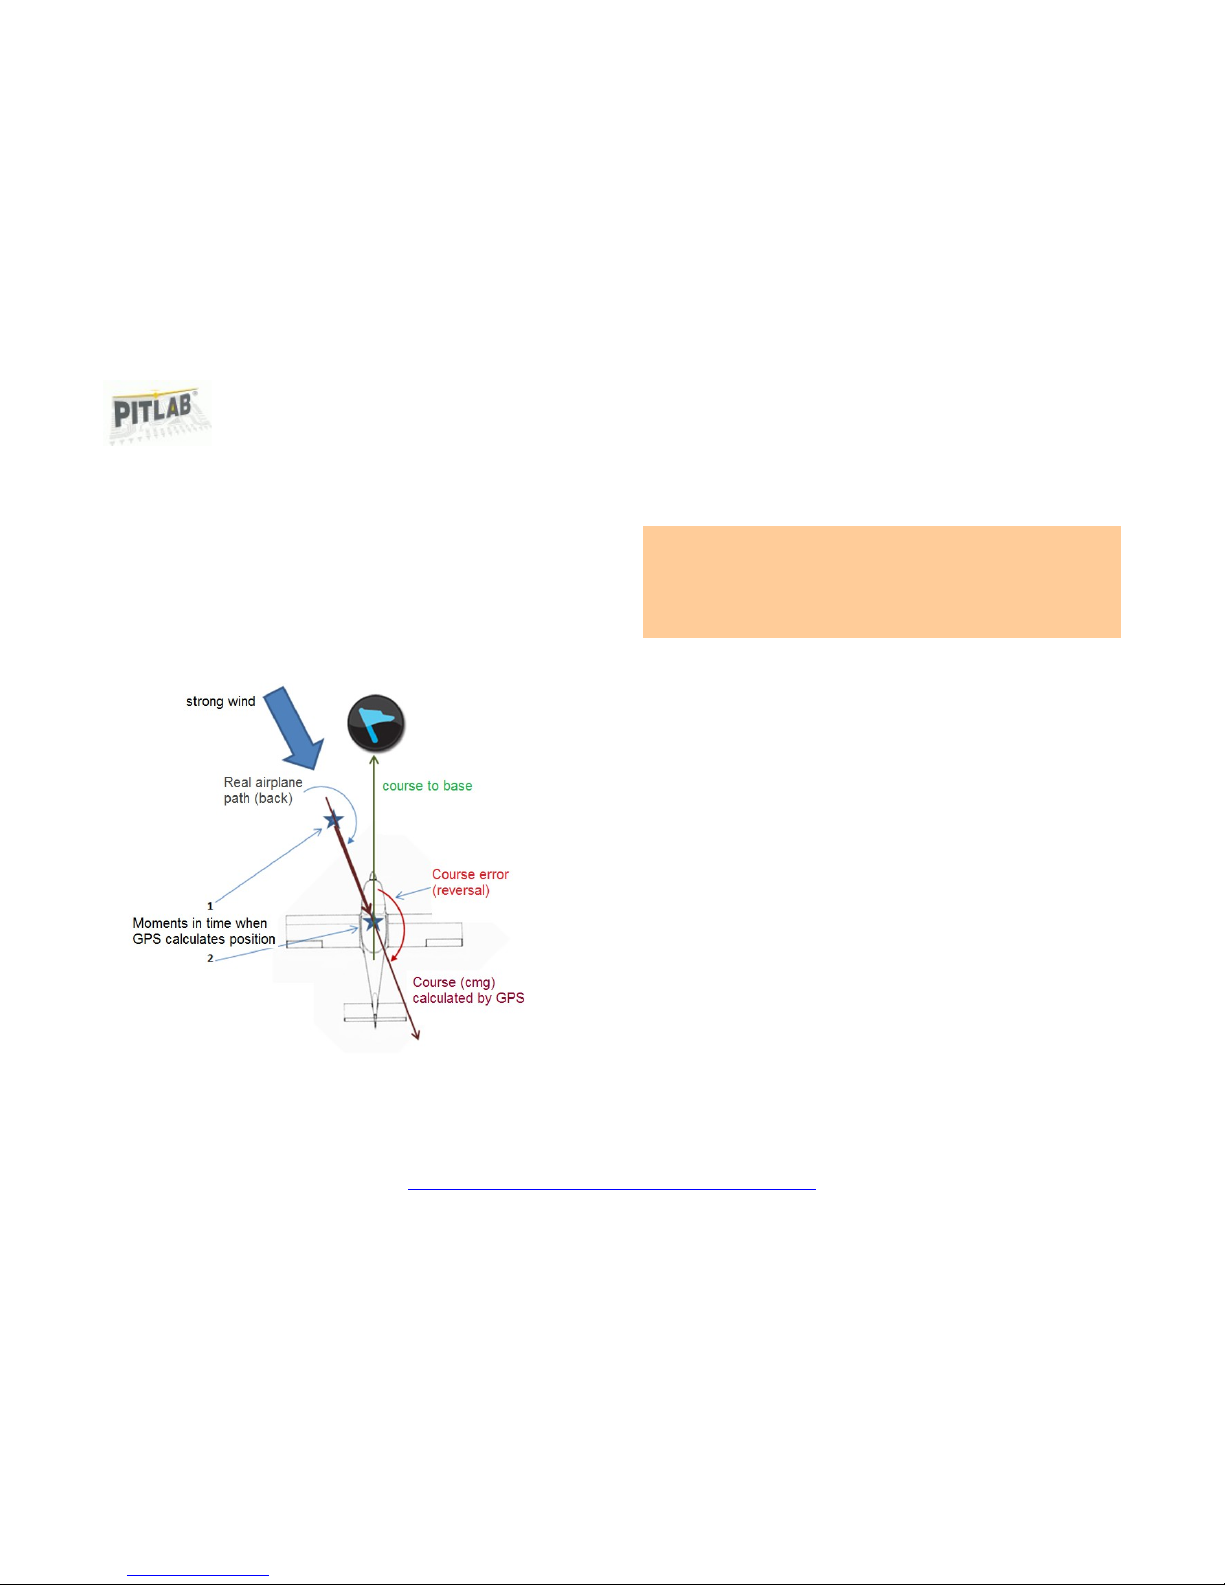
For flights in strong winds there is a risk that the model gliding into the
wind stands still or moves backward (free glide speed is less than the
wind speed), and when the model goes back , the course indicated by the
GPS becomes the opposite to the direction the model is heading. The
result is that the autopilot is doing a circle, trying to get back on the
correct course. These phenomena can make the autopilot to be unable to
return to base.
Figure 15 Reversal of GPS course when backing up the model in strong
winds
Setting the minimum speed of the GPS (speed vs. ground) causes the
autopilot to start the engine whenever the current GPS speed is below
this speed, eliminating the risk of model regression (getting away from
the base), and turning with the wind.
NOTE: In order to increase the speed (above the set minimum GPS
speed) the autopilot can also use the value of the gas set above the limit
of gas. The algorithms applied are designed solely to eliminate the risk of
model regression against the wind, the control of gas may not be
smooth, and the algorithms for altitude keeping can work less effectively.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 14 of 21
Page 15
Autopilot – User's manual
Saving the trimmers
Before the first flight, and after each change of trim model, save for the
autopilot linkage positions (PPM signal values) corresponding to level
flight of the model. Use this option in the OSD autopilot-> save trimmers.
Saving the trimmers is important from the point of view of the autopilot,
as in AUTO mode the autopilot takes over the role of RC transmitter and
needs to know the PPM signal values (modulation of servos)
corresponding to free flight in a straight line, with no banking and no stall
of the model. Changing the trim without saving it in the autopilot will
result in banking and turning of model in STAB mode, and a worse
operation of autonomous flight mode (asymmetric turns and, in extreme
cases, stall or problems with maintaining altitude).
Saving the trim can be done both on the ground and in flight. Trimming
the model on the fly should be made in OFF mode (with stabilization off)
in order to correctly observe the behavior of the model in free flight.
NOTE: saving the trim should always be made with the gas set at a
minimum. The gas trimmer saving is significant in models with
combustion engines, allowing for maintaining appropriate minimum
engine speed during flight in autonomous mode.
Choosing between GPS or magnetic course
Autopilot allows you to select the method of determining the course to
base by a built-in GPS or by electronic compass. The choice is made in the
OSD menu Service settings-> course.
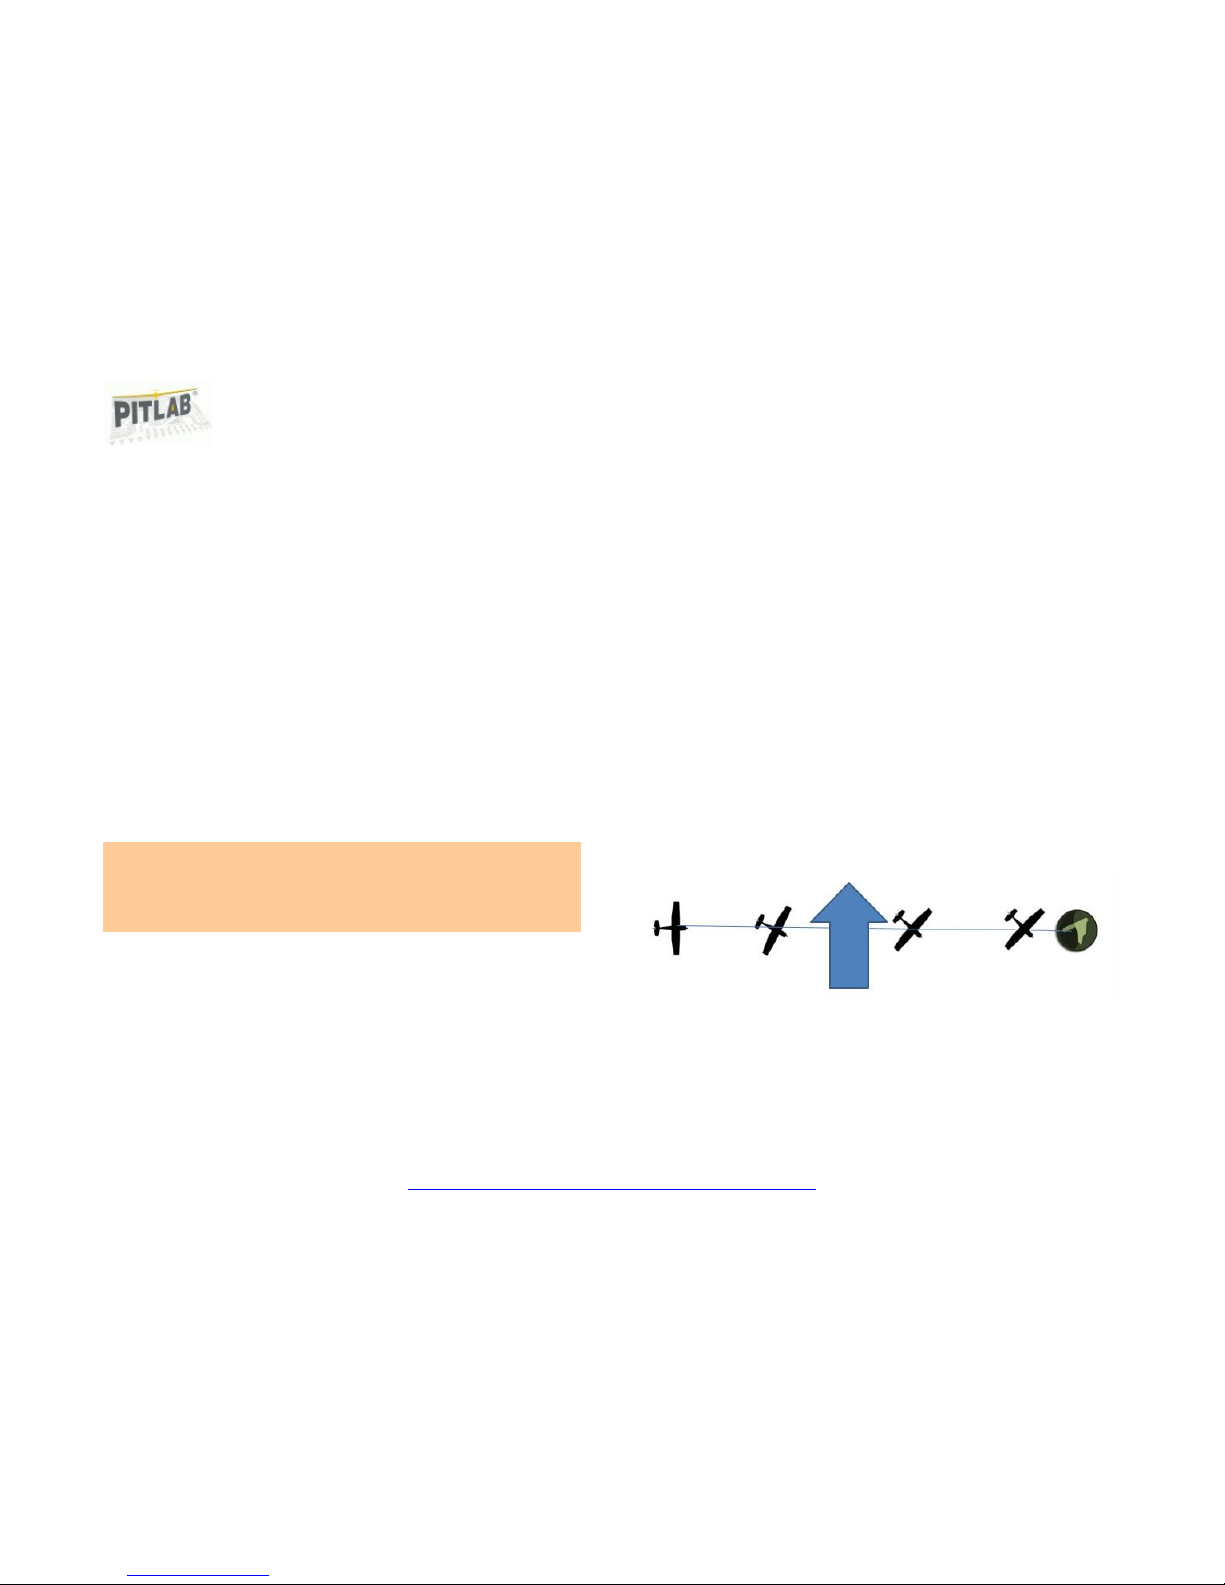
GPS determines the course on the basis of the position of the model
calculated in the consecutive points in time. So it is always the actual
direction of movement of the model, including pushing the model away
by the wind. This is called the Course Made Good CMG . Autopilot using
GPS course goes to the base in a straight line, along the shortest route,
but during the flight with side wind the model body is deflected from the
direction of the base direction so as to compensate for model drift by
wind. This deviation may be up to about 90 degrees, with a very strong
wind. For the pilot who observes view from a model camera for the first
time, this can be a surprise and may cause confusion, because the model
gives the impression of flying in the wrong direction (too much into the
wind).
Figure 16 flight in strong winds according to GPS (cmg)
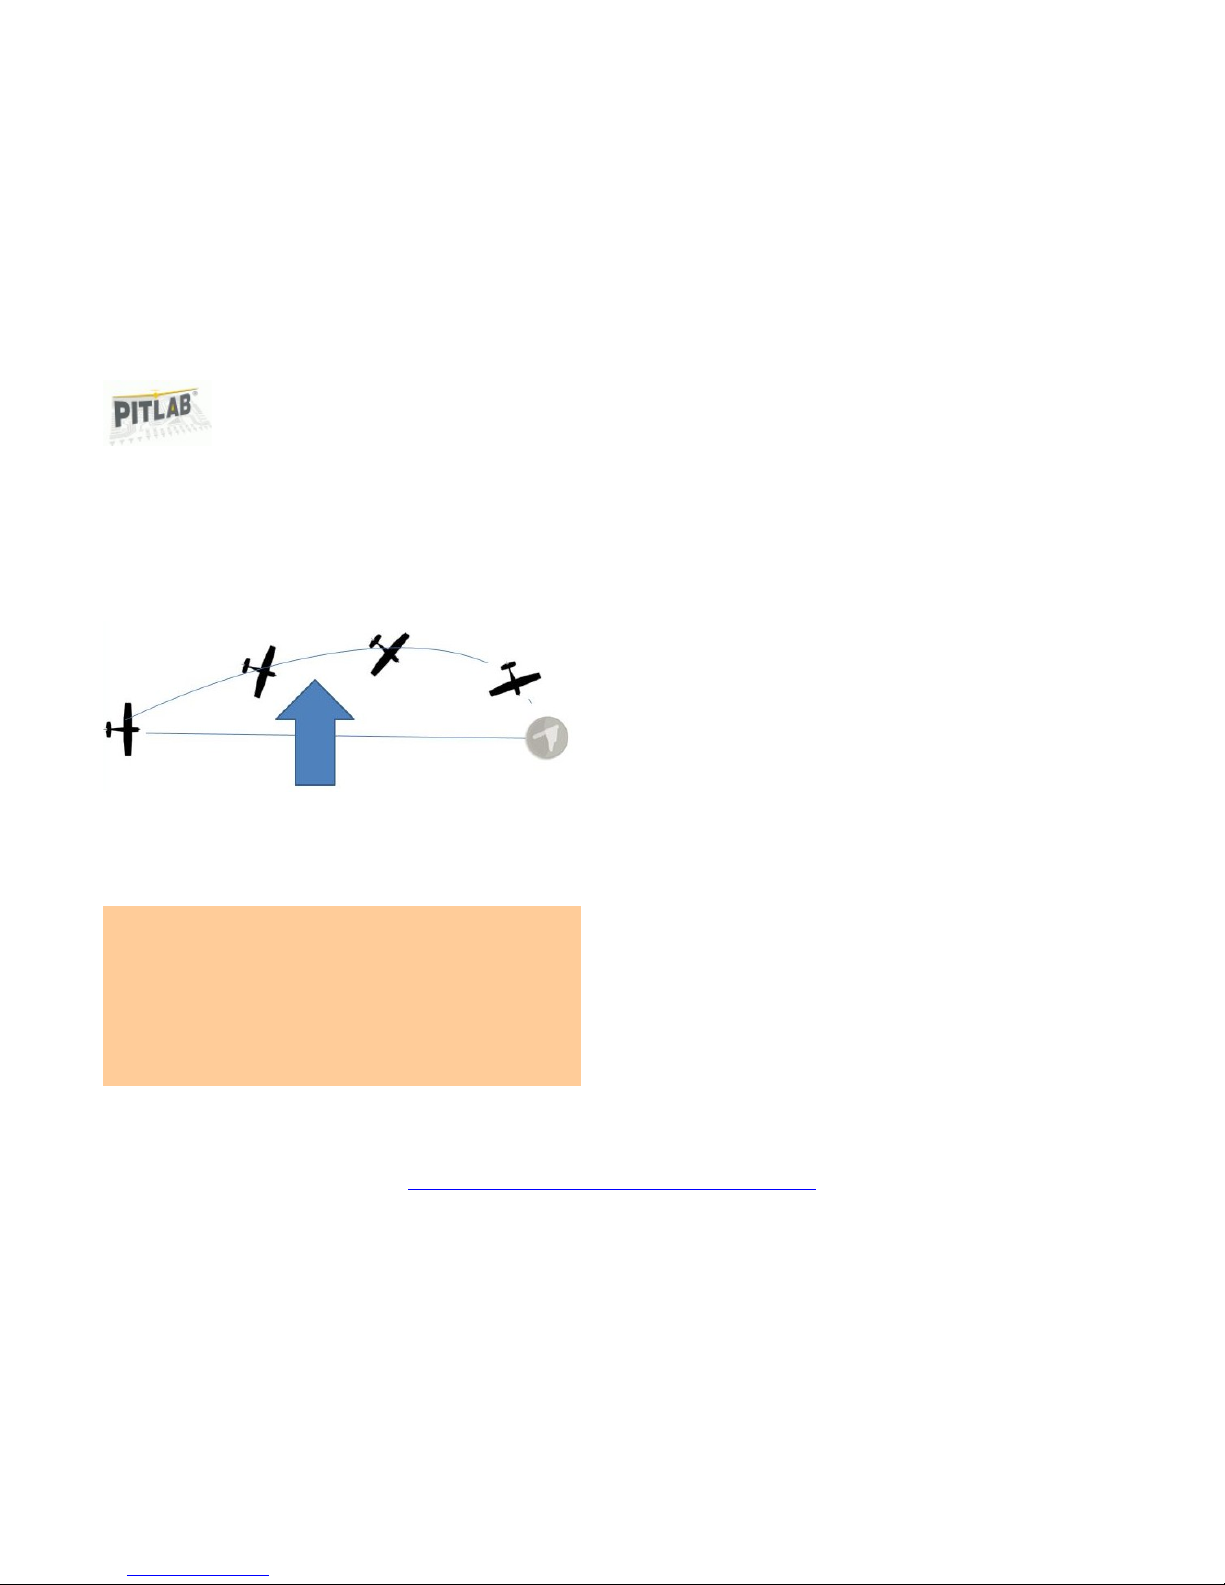
During the flight with the magnetic course the body is always in line with
the base direction, and the pilot observing a view from camera on board
should see destination point (base) directly in front of the model, but the
model is constantly pushed away by the wind, and despite turning all the
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 15 of 21
Page 16
Autopilot – User's manual
time in the direction of the base flies in an arc and at the end of the flight
is always hitting the base against the wind. In this case, the distance
traveled by the model is longer than the optimum. The advantage of
magnetic heading is also that, regardless of whether the model is moving
forward or in a strong wind gusts moves back it is always directed
towards the base.
Figure 17 flight in strong winds according to magnetic course
NOTE: The magnetic field sensor (electronic compass) is sensitive to any
kind of disturbance of the magnetic field caused by the presence of the
magnets (e.g. magnetic latches of cabin, neodymium magnets inside
motor), the magnetic fields generated by flowing current (power cables
to the motor) and metal (magnetic) objects near the sensor, such as
plates, brackets, bayonets, etc. Therefore, you should check if the
directions indicated by the electronic compass of the Autopilot coincide
with the actual geographic directions.
Choosing GPS or barometric altimeter
Autopilot allows you to select the type of altimeter, which is used to
maintain altitude in AUTO mode and indicates the altitude of on-screen
display.
Barometric altimeter is recommended for most flights. It provides high
precision of determining the altitude and its change, which can provide
information about the speed of descent or ascent of the model
(variometer) with accuracy of 0.1 - 0.2 m / s, but it is sensitive to changes
in atmospheric pressure, so during the flight and after landing the
altitude indicated by the altimeter can change within a few meters in
comparison to the initial value.
GPS altimeter is insensitive to weather conditions and provides a small
percentage error at high altitudes, however, poses a significant absolute
error of indications and its height can change unexpectedly and jump up
and down even in tenth of meters. Therefore, when using altitude from
GPS the variometer that indicates the rate of ascent / descent is not
available. GPS altitude can be used in high or prolonged flights in
changeable weather conditions.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 16 of 21
Page 17
Autopilot – User's manual
Waypoints
OSD allows you to define up to nine points of the route, which can be
used for a flight on a particular route, both in controlled flight and
autonomous flight.
Waypoints managing takes place in the OSD menu Waypoints. Waypoints
are described by GPS coordinates (altitude and latitude), and the cruising
altitude to the waypoint (in relation to the altitude of the starting point).
Selection of the flight starting from the first defined waypoint is
accomplished by selection OSD Waypoints-> Set flight according to points
along the route.
You can also choose to fly starting from any point along the route,
choosing the desired waypoint and then selecting from the submenu:
flight from the selected point.
After selecting the initial waypoint the navigation switches (indicating the
target course) to the first point of the route, and the autopilot display in
the info box is WP displayed (called a waypoint) and the number of the
current waypoint.
NOTE: The setting of flight along points along the route of flight in the
manual operation mode (STAB and OFF) switches navigation (indicating
the distance and course deviation) to the selected route (waypoint), and
not to return to base. This allows manual flight to the selected
destination, it should be borne in mind, and before returning to the base
you need to switch navigation in OSD menu Waypoints-> Set: Return to
base.
After approaching a waypoint at a distance of less than 50m the waypoint
is “checked” and navigation switched to the next waypoint.
NOTE: empty (not filled in) waypoints are ignored, and next defined
waypoint is selected.
Autonomous flight along the points along the route is activated by a
change in autopilot mode to AUTO and lifting the gas rod to the middle
position. With gas position at minimum , the autopilot always performs
navigation and return to the starting point.
At any time you can stop navigating (and flight) along points along the
route, choosing the OSD menu Waypoints-> Set: Return to base.
During the flight you can save your current GPS position of the model as a
new waypoint. To do this, select the waypoint at which you want to save
the current GPS position of the model, and then select the command Use
the GPS position. This way you can remember for example the highest
achieved flight distance or location of the point of interest along the
route, and then check its location in Google Maps.
NOTE: The most convenient way of trajectory planning is to use PC
application FPV_manager.exe, manage waypoints against the map
service Google Maps, and send points to the OSD via a USB connection.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 17 of 21
Page 18
Autopilot – User's manual
PC application configuration
Autopilot can be configured and updated via the USB port using FPV
manager software, running on a computer that is running Windows XP,
Vista, Win7 and Win8, in both 32 and 64 bit versions.
Configuration application (executable file FPV_manager.EXE) requires to
operate the. NET Framework software version 3.5, which is shipped with
the new versions of Windows and does not require any additional
installation. But it is possible that with the older versions of Windows XP,
the software is not available, then it must be downloaded from the
Microsoft and installed on your system:
http://www.microsoft.com/downloads/pl-pl/details.aspx?
FamilyID=333325fd-ae52-4e35-b531-508d977d32a6
The latest version of the configuration software can always be found on
the manufacturer's website:
https://www.pitlab.com/fpv-system/download.html
The configuration application is ready for use immediately after
downloading to a local drive or removable drive and does not require
installation on Windows. The application can be run from anywhere, even
from removable media such USB flash drive or directly from a network
location, on any Windows computer.
The application communicates with the controller pad via USB and
standard mini-USB cable. Windows automatically recognizes the
connected device, without the need to install additional drivers. The
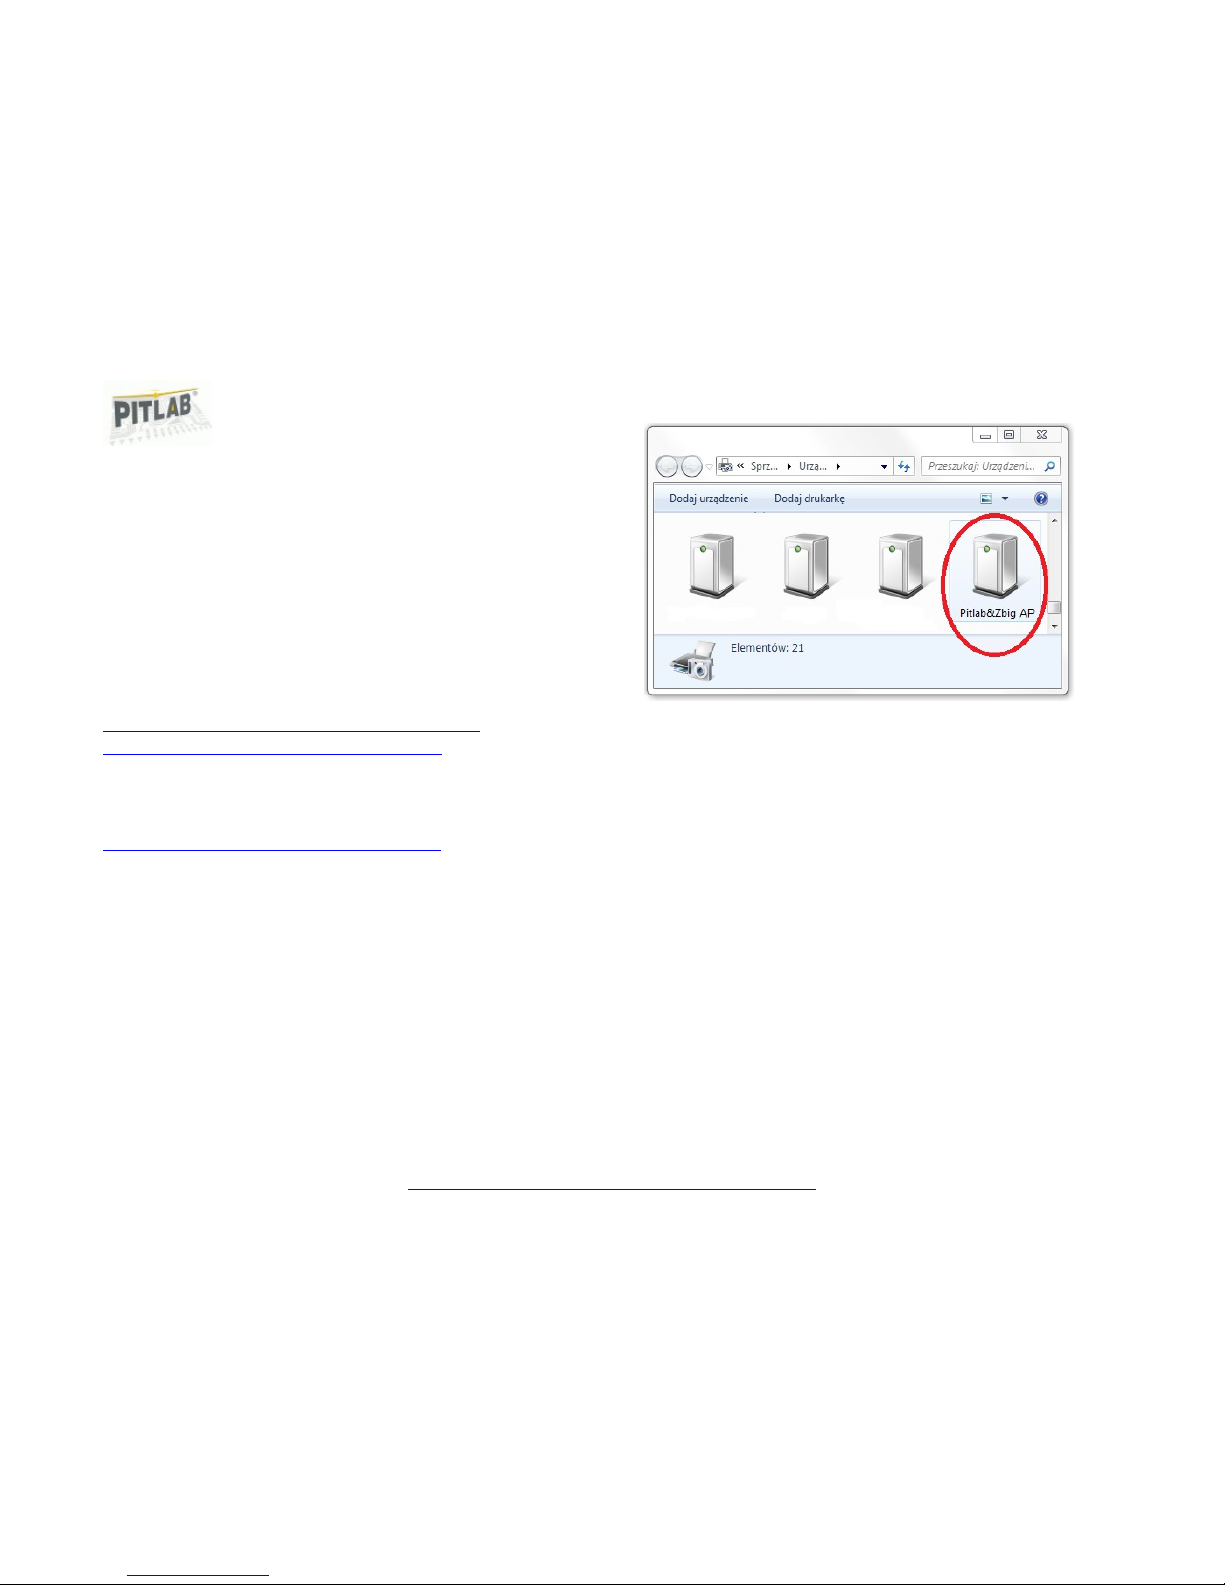
device is seen in Windows as Pitlab & Zbig AP.
Once the FPV manager application is started, go to the Autopilot tab. If
the device is connected to your computer, it be the automatically
identified and the subpage Firmware displays basic information about the
device.
Software Update
Manufacturer makes updated Autopilot software (firmware) available on
its website, including functional enhancements and fixes. To update the
software, the file with the new firmware version (with. AP extension)
should be copied to the local disk, and then click Upload Firmware button
and select the new firmware file. The update process takes from a few to
several seconds, and the progress is indicated by a progress bar in an
application FPV manager.
RC Setup
Configuration and the correct connection of the receiver verification can
be made in the FPV_manager application, Autopilot tab-> Radio PPM.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 18 of 21
Page 19
Autopilot – User's manual
In the PPM Input frame current signal levels from each receiver channel
or serial signal decoded PPM (CPPM) are presented.
In the PPM Output frame current output signals of autopilot: control
servos and motor controller are presented.
In the PPM Input mode and mapping frame you can find settings for
cooperation with RC receiver through parallel connection (parallel
inputs), or one of the two Serial PPM (CPPM)inputs - Input 1 or 6. Here
we make the appropriate channel assignments of the CPPM signal to the
autopilot function, and additional PPM Aux2 to AUX5 outputs.
Calibrations
Autopilot is factory calibrated and ready to operate, and you will not
need to calibrate the device on your own.
However, there can be special circumstances in which it will be necessary
to re-calibrate the system if there are problems with its proper operation.
Problems may arise as a result of strong mechanical or thermal shocks, or
natural aging of electronic components. This FPV_manager application
allows you to perform additional Autopilot calibration (in order to
shorten the maintenance of the device), but before using any calibration
function you should contact the manufacturer to determine the nature
and cause of the problem, and obtain instructions on how to calibrate it
properly.
Calibrating Gyroscope
The gyroscope is very important sensor for flight stabilization. It
detect rotation speed in all 3 axis. Due to complex electro-mechanical
nature of the principle of measurement, it is exposed for offset error
(detecting zero speed) depending mainly from temperature change
and mechanical tension. Although gyroscope is fully factory
calibrated, in some cases (change of mechanical tension, excessive
temperature change or strong mechanical shock) it needs to be recalibrated by the user.
Because gyroscope measures rotation speed during calibration
process the autopilot (or whole plane with it) has to be very stable,
not exposed to any movement nor vibration. Position of autopilot
during calibration is not important.
The principle of calibration is to determine the current offset for a
given temperature for all axis. It require to determine offset in 3
different temperatures: “low”, “mid” and “high”, to estimate individual
curve of drift change in function of temperature.
The “mid” (or room) temperature should be close to 25°C. The “low”
and “high” temperatures should cover (or be close to) range of
temperatures in which autopilot will be used. If you are planning to
operate in extremal condition: very hot or very cold, you may extend
the temperatures of calibration. The factory calibration is done at
“low” temperature -10°C, “mid” equal 25°C and “high” equal 40°C.
The calibration can be done by 2 ways: using FPV Manager or using
OSD menu operated via 3-key keyboard (operation via RC channel
don't support calibration for safety reasons). Calibration using OSD
menu is more natural for assembled planes, but require correct
sequence of cooling and heating. Calibration via FPV Manager require
connecting USB cable, but give freedom in calibration sequence.
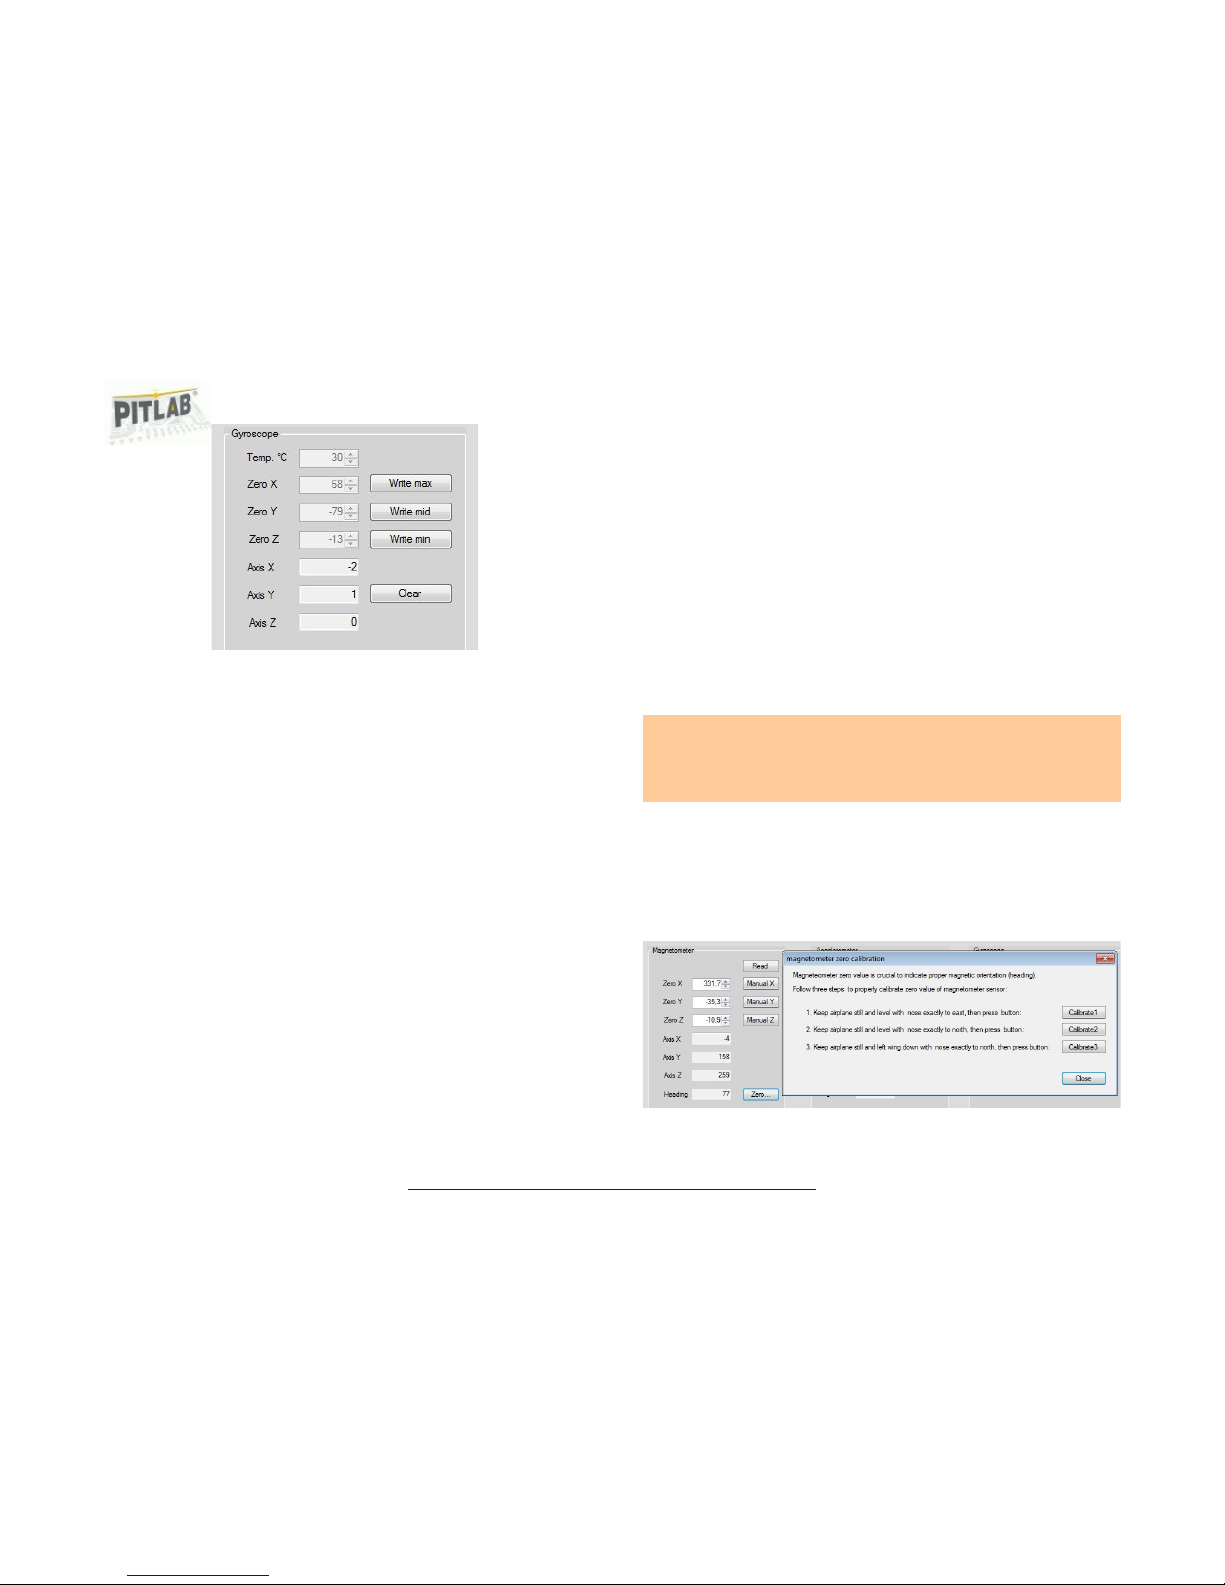
To calibrate via FPV Manager select “Autopilot” → “Calibration”.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 19 of 21
Page 20
Autopilot – User's manual
Well calibrated gyroscope should has values “Axis X”, “Axis Y” and “Axis
Z” near zero. It may fluctuate, but it's value should be not bigger then
+/-10 units. If offset is bigger on any axis, it means the gyroscope
require calibration.
First autopilot board need to be cooled (e.g. in refrigerator, covered
with plastic bag). When board is stable, press button “Write min”. Next
allow to slowly warm up board to room temperature (close to 25°C)
and press button “Write mid”. Finally heat the board using hair dryer
or other safe heat source and press “Write max”.
For cooling can be used outdoor temperatures in winter, ice cube in
foil bag or specialized cooling spray. Using ice or sprays please cover
the electronics with thin tissue to absorb water condensing from air.
Correct sequence: first cooling, next heating allow to evaporate
potentially condensed moisture.
To calibrate via OSD menu go to OSD menu “Service” → “IMU
calibration” → “Thermal calibration” and follow instruction on the
screen. First you will be asking for calibrate “mid” temperature and
don't moving the model while calibration, next cooling and calibrating
“low” temperature. Finally heating and calibrating “high” temperature.
Calibrating magnetometer
Principle of magnetometer calibration is to find minimal and maximal
magnetic field value for all axis. To do it, the autopilot board (or whole
plane with it) should be oriented to the magnetic north direction in 3
different position to calibrate all 3 axis.
The calibration can be done via FPV Manager at office condition or via
OSD menu outdoor. The outdoor conditions are recommended,
because inside building the magnetic field can be highly distorted by
iron used in building construction. In both ways of calibration, user is
asked to keep the autopilot oriented to described direction in 3D
space. To do it precise the magnetic compass will be useful to precise
determine north direction before calibration.
Note: The compass is also the source of magnetic field, so when is
kept in close distance to magnetometer on autopilot's board, it may
distort the Earth magnetic field. Take it away from board during
calibration.
To calibrate using FPV Manager use “Autopilot” → “Calibration”. In
“Magnetometer” section, press “Zero” button and follow instruction
displayed in window. Place autopilot board or whole plane in
requested position and press the button “Calibrate 1”. Follow the same
operation for next 2 steps in any order.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 20 of 21
Page 21
Autopilot – User's manual
To calibrate using OSD menu (using keyboard instead RC channel as a
input) call menu “Service” → “IMU calibration” → “Magnetometer
calibration” and follow commands displayed on the screen.
The quality check of magnetometer calibration can be done by
observing heading displayed on OSD screen while slowly rotating
around own axis. The displayed magnetic scale should cover with real
magnetic directions and should change with the same speed as
rotating speed. Bad calibration may cause some course values will not
exist and slowly rotating the plane with autopilot, the displayed
course value will skip some values and extend other.
Calibrating accelerometer
The accelerometer in IMU is used to point direction to Earth by it's
gravity vector and compensating slowly growing error of artificial
horizon position caused by gyroscope drift. Principle of operation is
quite simple and not influenced by so many errors like in cause of
gyroscope or magnetometer, so it not require correction of
temperature drift. Calibration is limited to find value of zero gravity
for all axes and use it as a reference point.
Correctly calibrated accelerometer in FPV Manager → “Autopilot” →
“Calibration” → “Accelerometer” should indicate “g-force” equal 1.0.
Also plane placed levelled in position in flight should have values “Axis
X” and “Axis Y” close to zero and value of “Axis Z” close to 4096.
To calibrate accelerometer first place plane or autopilot board (much
easier) in perfectly levelled position and next press “Zero X,Y” button.
To calibrate Z axis first enter 0 into “Zero Z” field and press “Manual Z”
button. Next rotate the autopilot by 90° to be laying on side (plane
should have one wing down, another up (not important which one) so
the Z axis should indicate no gravity. Remember the value in “Axis Z”
field and rewrite it to “Zero Z” field and save using “Manual Z” button.
© Pit Lab 2017 https://www.pitlab.com/fpv-system/autopilot.html Page 21 of 21
 Loading...