

Page 1
User’s Guide
Shop online at
omega.com
e-mail: [email protected]
For latest product manuals:
www.omegamanual.info
LDX-D
Page 2
omega.com [email protected]
Servicing North America:
U.S.A. Omega Engineering, Inc.
Headquarters: Toll-Free: 1-800-826-6342 (USA & Canada only)
Customer Service: 1-800-622-2378 (USA & Canada only)
Engineering Service: 1-800-872-9436 (USA & Canada only)
Tel: (203) 359-1660 Fax: (203) 359-7700
e-mail: [email protected]
For Other Locations Visit omega.com/worldwide
INDEX
1.0 Safety Information
1.1 Electrostatic discharge
2.0 Installation
2.1 Mounting and Access
2.2 ConnectionsandLinkIdentication
2.3 Description of Links
2.4 Primary Frequency
2.5 Transducer Input Load
2.6 Bandwidth
2.7 BasicConguration
2.8 Output Descriptions
2.9 Connections
2.10 Placement and EMC
2.11 LDX-D Synchronization
3.0 Setting Up
3.1 Set-up Summary
4.0 MATH Functions
4.1 MATH Introduction
4.2 MATH Set-up Procedure
5.0 Transducer Sensitivity
5.1 X1, X2, X5 and DIV2 Link
6.0 Application
6.1 Application Example
7.0 Specication
7.1 Mechanical Outline
7.2 TechnicalSpecication
Return of Goods
1
The information contained in this document is believed to be correct, but OMEGA accepts no liability for any errors it contains,
and reserves the right to alter specifications without notice.
Page 3
1.0: Safety Information
Terms in this Manual
WARNING statements identify conditions or
practices that could result in personal injury or loss of life.
CAUTION statements identify conditions or practices that could result in damage to
the equipment or other property.
Symbols in this manual
This symbol indicates where applicable
cautionary or other information is to be
found.
Warnigns & Cautions
WARNING: Do not operate in an explosive atmosphere
WARNING: Safety critical environments
This equipment is not intended for use in a safety critical environment
CAUTION: Low voltage
This equipment operates at below the SELV and is therefore outside the scope of
the Low Voltage Directive.
This equipment is designed to work from a low voltage DC supply. Do not operate
thisequipmentoutsideofspecication.
1.1 CAUTION: Electrostatic Discharge
This equipment is susceptible to electrostatic discharge (ESD) when being installed
or adjusted, or whenever the case cover is removed. To prevent ESD related
damage, handle the conditioning electronics by its case and do not touch the
connector pins.
During installation, please observe the following guidelines:
• Ensureallpowersuppliesareturnedo.
• If possible, wear an ESD strap connected to ground. If this is not possible,
discharge yourself by touching a metal part of the equipment into which the
conditioning electronics is being installed.
• Connectthetransducerandpowersupplieswiththepowerswitchedo.
• Ensure any tools used are discharged by contacting them against a metal part
of the equipment into which the conditioning electronics is being installed.
• Duringsettingupoftheconditioningelectronics,makelinkconguration
changeswiththepowersupplyturnedo.Avoidtouchinganyother
components.
• Makethenalgainandosetpotentiometeradjustments,withpowerapplied,
using an appropriate potentiometer adjustment tool or a small insulated
screwdriver.
Page 4
2.0: Installation
1 2 43
2.1: Mounting and Access
Before mounting the LDX-D, please refer to section 2.10.
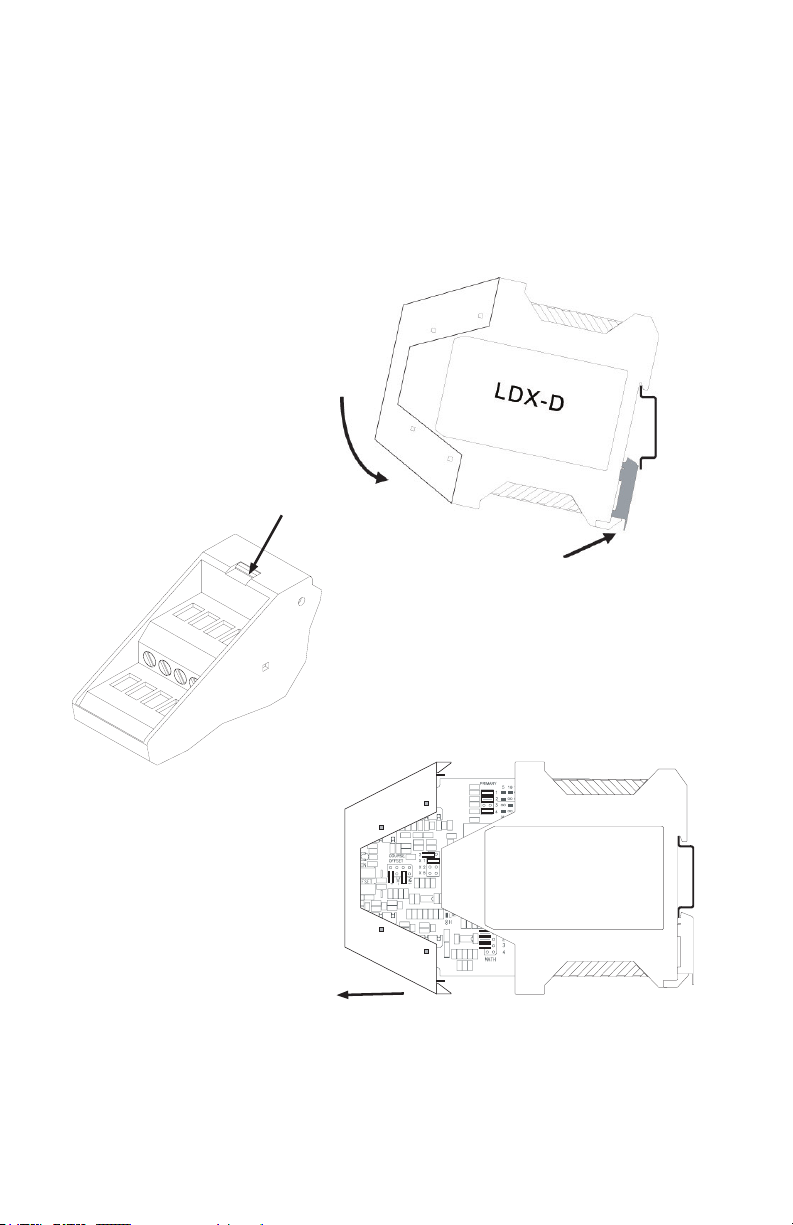
Hook the LDX-D on the DIN rail with the release clip facing down and push onto
the rail until a ‘click’ is heard.
To remove, use a screwdriver to lever the release clip down. Pull the bottom of
the housing away from the rail and unhook.
DIN Rail
Cover release latch
LDX-D
DRC
Withdraw PCB
To access internal links, the front cover and PCB must be withdrawn from the
housing. Use a screwdriver or similar tool to depress the top latch. The cover will
spring forward. Repeat with the bottom latch, then gently pull the PCB out.
Page 5
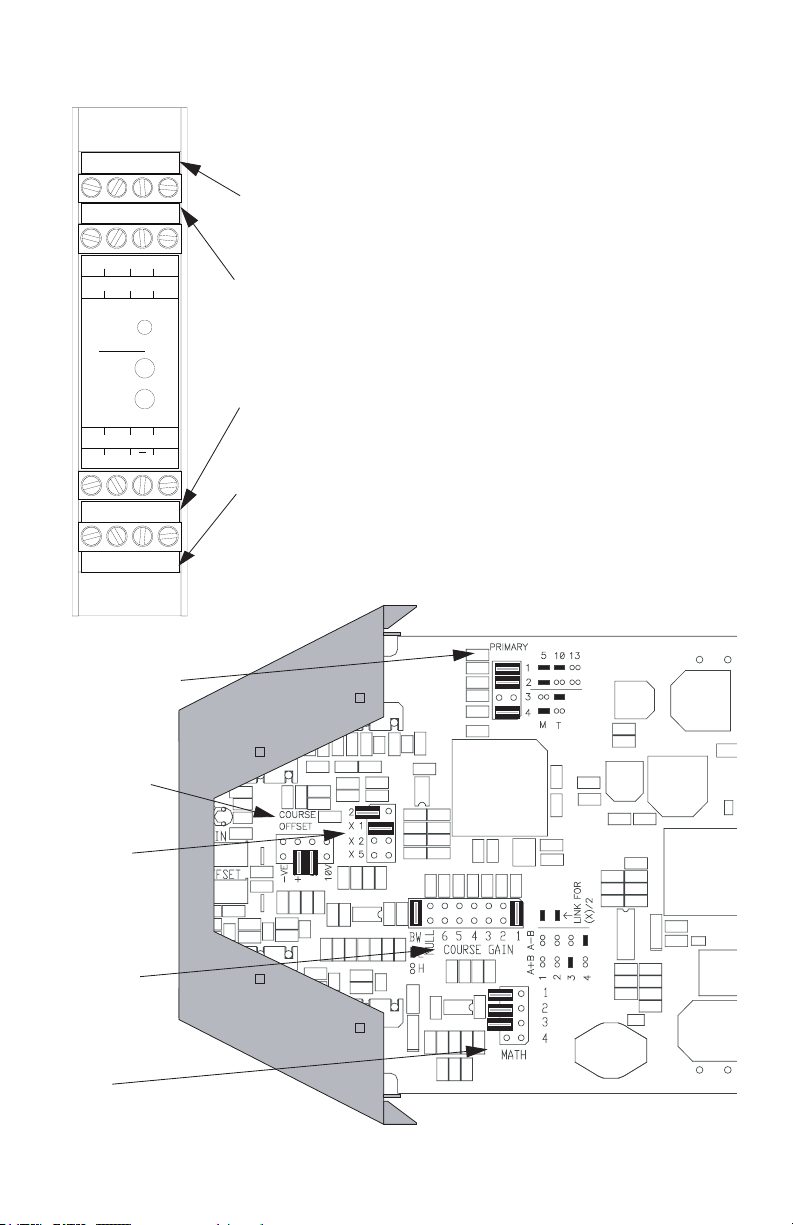
2.2: Connectionsandlinkidentication
78
34
Transducer
12
56
Power
Fine Adjust
Gain
Offset
output
power
4
8
12
+
16
1
sy1 sy2 pri1 pri2
5
scn CT sec1 sec2
Vout Mout 0V Iout
9
Min Mout#
13
9101112
13 14 15 16
• Primary Frequency
• Synchronization
1 Synchronization 1
2 Synchronization 2
3 Primary (red)
4 Primary (blue)
5 Screen (0 V)
6 CT (yellow)
7 Secondary (green)
8 Secondary (white)
Power Supply & Outputs
9 Voltage Output
10 Math OUT
11 Signal 0 V
12 Current OUT
13 Math External IN
14 Inverted Math OUT
15 –VE power supply
16 +VE power supply
• Coarse Oset
• Input Load
• Input Gain
• Coarse Gain
• Bandwidth
• Null at set-up
• Maths
Terminals 5, 11, and 15 are internally connected but, for best performance, they should be
treated as separate terminals.
Note: If the output polarity is incorrect, reverse the transducer secondary connections
Page 6
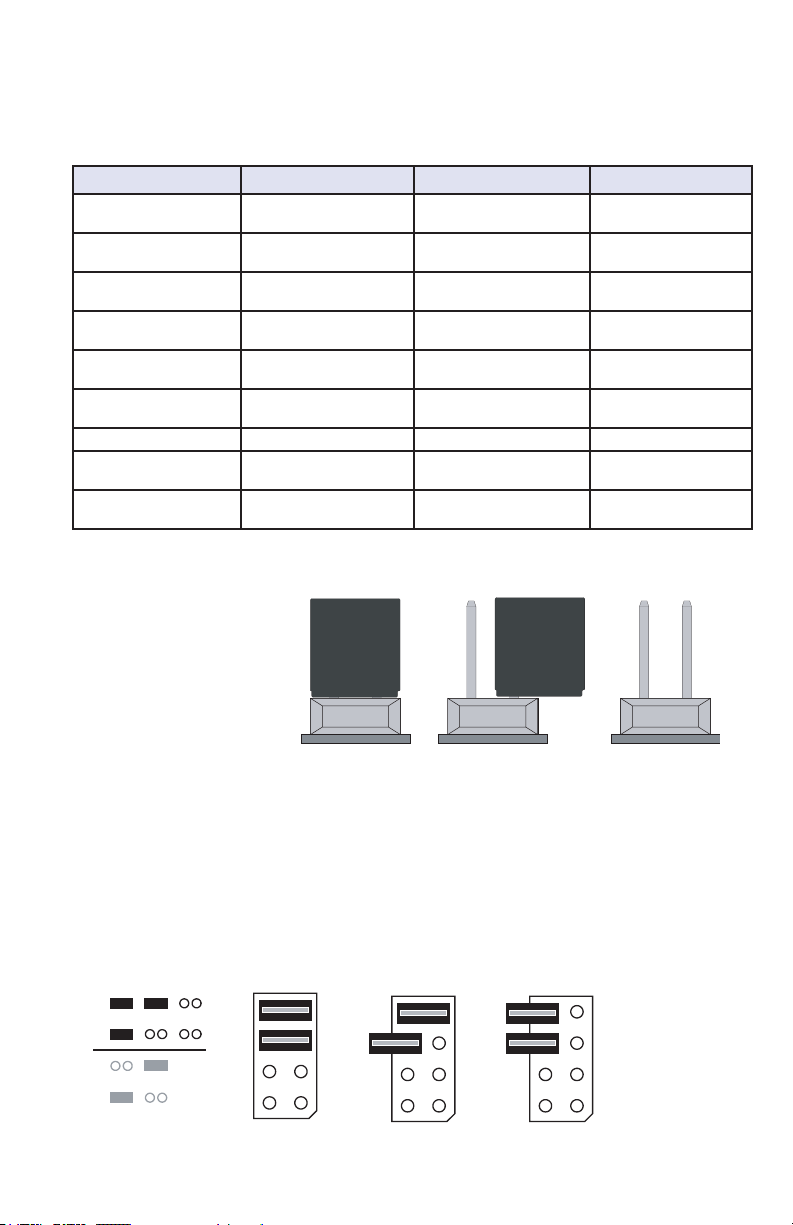
2.3: Description of links
Link ON Link PARKED
5 10 13
1
2
3
4
1
2
3
4
The table below and subsequent diagrams explain the link functions and detail
the factory settings.
Link Description Options Factory Setting
COARSE GAIN Select coarse output
gain
COARSE OFFSET Select coarse output
offset
NULL Used during set-up to
null output
PRIMARY Select primary
frequency
MT Select synchronization
mode
INPUT LOAD Select transducer
secondary load
INPUT GAIN Input gain X1, X2, X5, DIV2 Link ON, X1
BW Sets output signal
bandwidth
MATH Enables maths option A+B, A-B, (A+B)/2,
Range 1 to 6 Link ON, position 1
+VE, -VE, 5 V, 10 V No offset, links
Output in null state or
enabled
5 kHz, 10 kHz, 13 kHz Both links ON, 5 kHz
Master or track Set as master
100 kW or 2 kW Link PARKED,
L = 500 Hz, H = 1 kHz Link ON, 500 Hz
(A-B)/2
PARKED
Link PARKED,
output enabled
100 kW
Links PARKED,
maths not set
Note: If the output polarity is incorrect, reverse the transducer secondary connections.
2.4: Primary Frequency
The LDX-D primary frequency is set using links as shown below. Transducer
specicationsdeterminetheoptimumfrequency.
Primary amplitude is not adjustable. The DRC uses ratiometric techniques and
is insensitive to primary amplitude. Maximum secondary transducer amplitudes
must be observed. Refer to section 5.1.
M T
1
2
3
4
5 kHz 10 kHz 13 kHz
1
2
3
4
Link OFF
Page 7
2.5: Transducer Input Load
The LDX-D has two input load ranges. 100kΩisoftenusedforLVDT
transducerswhile2kΩisoftenusedforHalfBridgetransducers.Ifloadsof
lessthan100kΩarerequired,anexternalresistormaybewiredacrossthe
SEC1andSEC2terminals.Mosttransducersperformwellinto100kΩ.See
specicationsection7.2forfurtherdetails.
100kΩ-linkPARKED
2kΩ-linkON
2.6: Bandwidth
The LDX-D has selectable bandwidth (BW). The bandwidth setting is
independent of other DRC settings. Where possible, the lowest bandwidth setting
should be used to minimize output noise.
500 Hz - Link ON
1 kHz - Link PARKED
Note: Total system bandwidth is dependent on probe type and application.
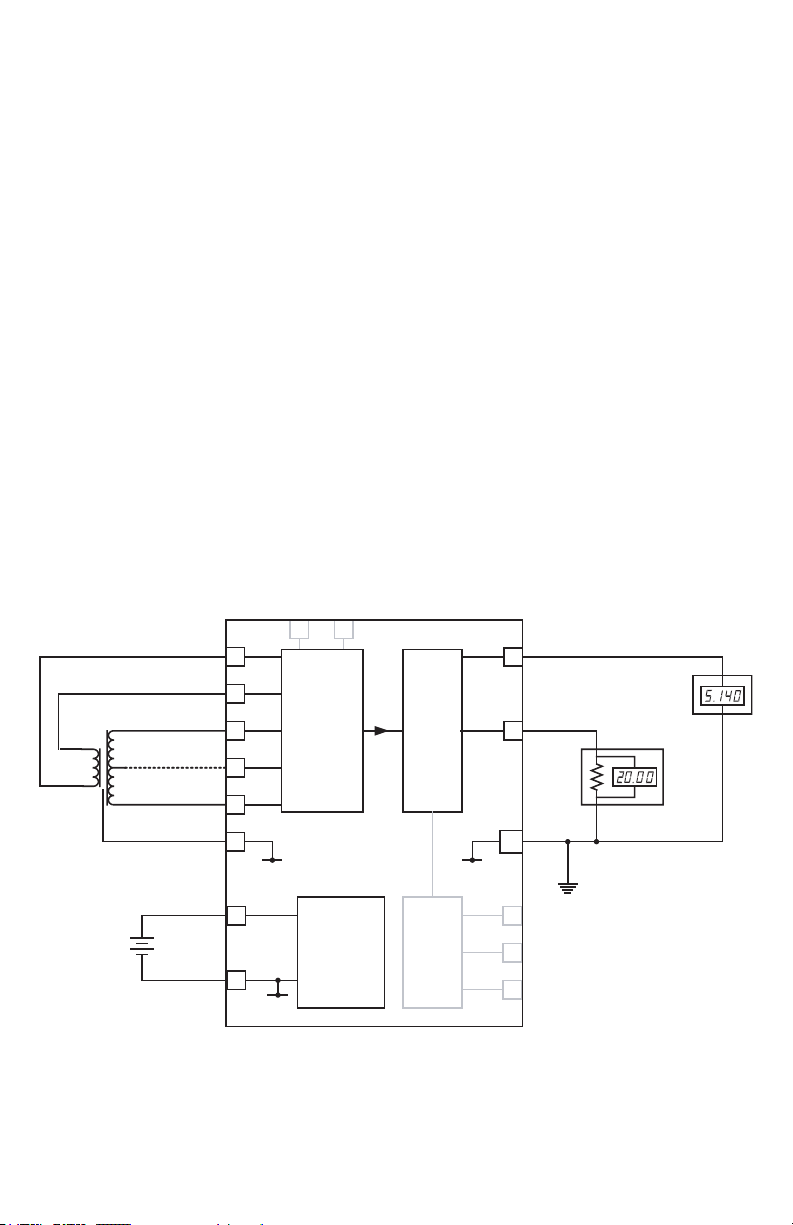
2.7:BasicConguration
Please refer to section 2.10 before installation.
Aoatingoutputpowersupplyisrecommendedasitwillminimizegroundloop
noise problems. Please refer to section 6.1 for a typical arrangement.
Sy1Sy2
0V
1 2
Transducer
Output
0V
(GND)
Vout
9
Voltage
Iout
12
Current
+
-
11
pri1
pri2
sec1
CT
sec2
screen
3
4
7
6
8
5
(GND)
+
-
Power Supply
10-30 VDC
+
16
Power
-
15
0V
(GND)
converter
Math
13
Min
Min
10
Mout
Mout
Voltage and current
Mout#
Mout#
14
connections are shown.
Generally only one type is
used.
Page 8
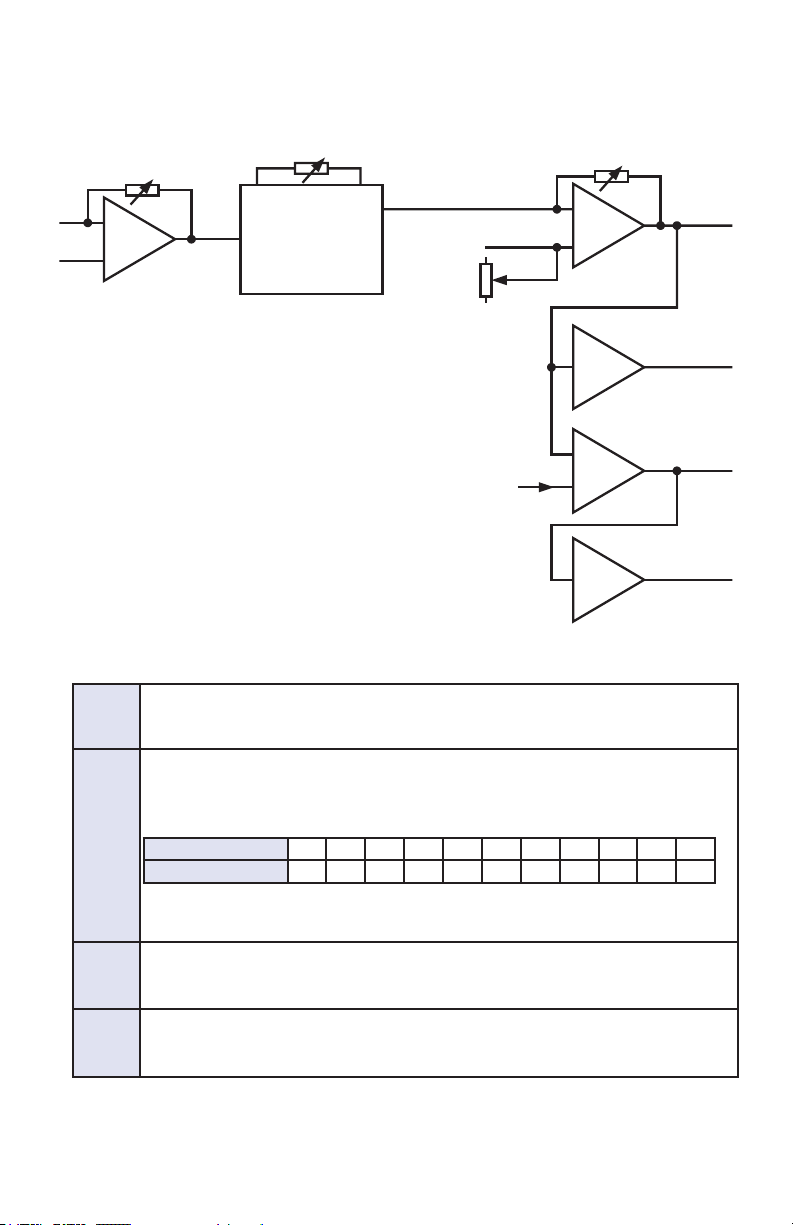
2.8: Output Descriptions
This section describes how the various outputs of the LDX-D are related.
Input Gain
Coarse Gain
Transducer
Circuits
+
Osets
-
Fine Gain
Vout
I a V
MATH
-1
Min
-1
Iout
Mout#
Mout
Vout This is a voltage output. The gain and offset controls are used to set the
required output range. All other outputs are affected by changes made to
Vout.
Iout This is a current output only, LDX-D is not loop powered. This can be set
for up to ±20 mA. A common output is 4-20 mA. The Iout is proportional to
Vout but cannot be independently adjusted. The approximate relationship
is shown below:
Voltage (V) -10 -8 -6 -4 -2 0 2 4 6 8 10
Current (mA) -20 -16 -12 -8 -4 0 4 8 12 16 20
When relating current to voltage, 4-20 mA is the same as a 2 to 10 V span
(or ±4 V with a +6 V offset).
Mout Mout is the main MATH output. This is a voltage output. Vout and Min are
combined in the MATH section. The output of this section is inverted to
keep the signal polarity the same as Vout.
Mout# This is an auxiliary voltage output. This is the direct output of the MATH
stage and is the inverse of Vout. If MATH options are not selected then
Mout a Mout# a Vout. Refer to section 4.1.
All outputs may be used at the same time but cannot be independently adjusted for
scalefactororoset.
Page 9
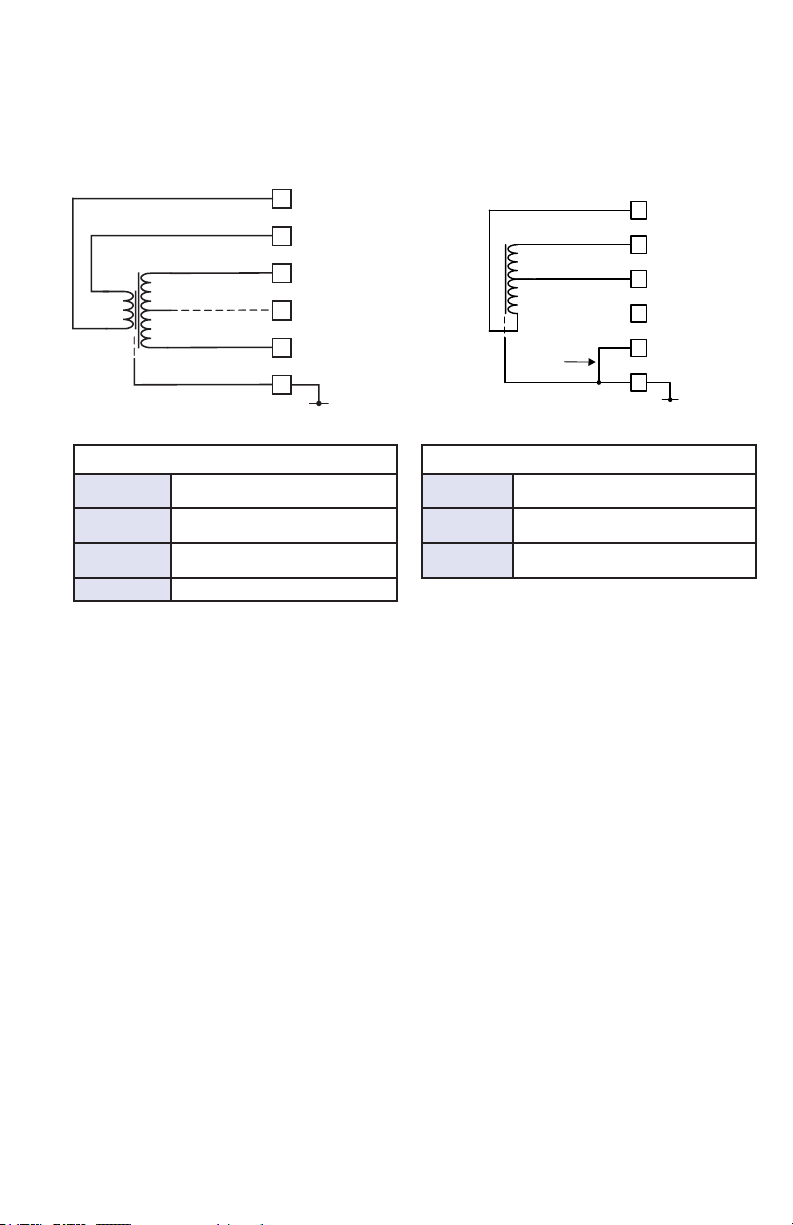
2.9: Connections
Pri1 (red)
The diagram in section 2.7 shows a basic connection with LVDT. The following
diagram gives further details of Omega LVDT transducers and alternative
connections for Half Bridge transducers.
Pri2 (blue)
Sec1 (green)
CT (yellow)
Sec2 (white)
screen
3
4
7
6
8
5
0 V (GND)
Half-Bridge
LINK
Screen
Pri1 (red)
Pri2 (blue)
Sec1 (yellow)
Sec
2
3
4
7
65CT
8
0V (GND)
LVDT Electrical Connections Half Bridge Electrical Connections
Red and
blue
Green and
white
Primary (energising)
Secondary (signal) Yellow Signal
Red and
blue
Energising
Yellow Secondary center tap Black Transducer body ground
Black Transducer body ground
The CT terminal is provided to terminate the center tap (CT) connection of a transducer if present. There is no electrical connection within the LDX-D. This is provided
toallowforquadraturecomponentstobettedifrequired.
2.10: Placement and EMC
LDX-D has been designed to comply with EMC regulations. For best performance,
the EMC compliance of surrounding equipment must be considered. High levels of
EMI(electromagneticinterference)canaecttheperformanceofLDX-D.
Residential, Commercial and Light Industrial Environments
Typicallythiswillbeanoce,laboratoryorindustrialenvironmentwherethereis
no equipment likely to produce high levels of electrical interference such as welders
or machine tools. Connections may be made using twisted unscreened wire which
isacost-eectiveoptiongivinggoodperformanceinthisenvironment.Standard
equipment wire such as 7/0.2 (24AWG) can be twisted together as required.
Standard data cable such as a generic CAT5 UTP will also give good performance.
Industrial Environments
Typically this will be an industrial environment where there is equipment likely to
produce high levels of electrical interference such as welders, large machine tools,
cutting or stamping machines. LDX-D should be mounted inside an industrial steel
enclosure designed for EMI screening. Many enclosures, though metal, are not
designed for good screening and so careful installation is important. Place LDX-D
away from equipment within the enclosure that is likely to produce high levels of
EMI.
Connections should be made using a screened cable (braided or foil screened
cables may be used). The cable screen should be connected to the housing at the
cable entry point. An EMC cable gland is recommended. If this is not possible, then
the unscreened section of cable should be kept as short as possible, and the screen
should be connected to a local ground.
Page 10
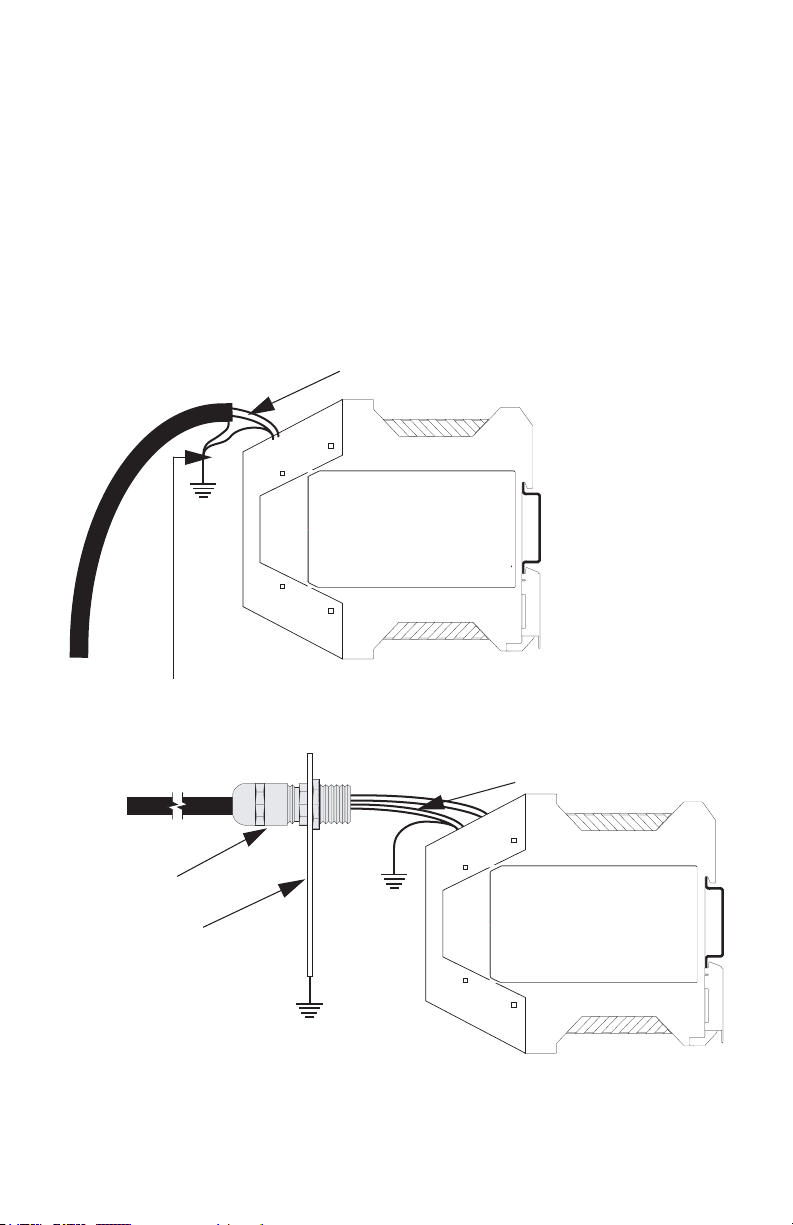
2.10: Placement and EMC (continued)
Where possible, the LDX-D should be the only ground connection point. If
voltage, current or power supplies are ground referenced and connected at some
distance from LDX-D, then noise may be introduced.
All 0 V terminals on LDX-D are connected internally. Ground 2 may be connected
to any of the LDX-D 0 V terminals, however terminal 11 is preferred. Screen
ground (ground 1) may be connected via terminal 11. Only one local ground is
needed for each LDX-D.
A local power supply is ideal but, if this is not possible, a screened cable
arrangement can be used to reduce noise picked up.
Keep exposed cable as short as possible
LDX-D
DRC
Connect screen to chassis ground
EMC gland
Enclosure
Ground
1
Keep exposed cable as short as possible
Ground
2
LDX-D
DRC
Page 11
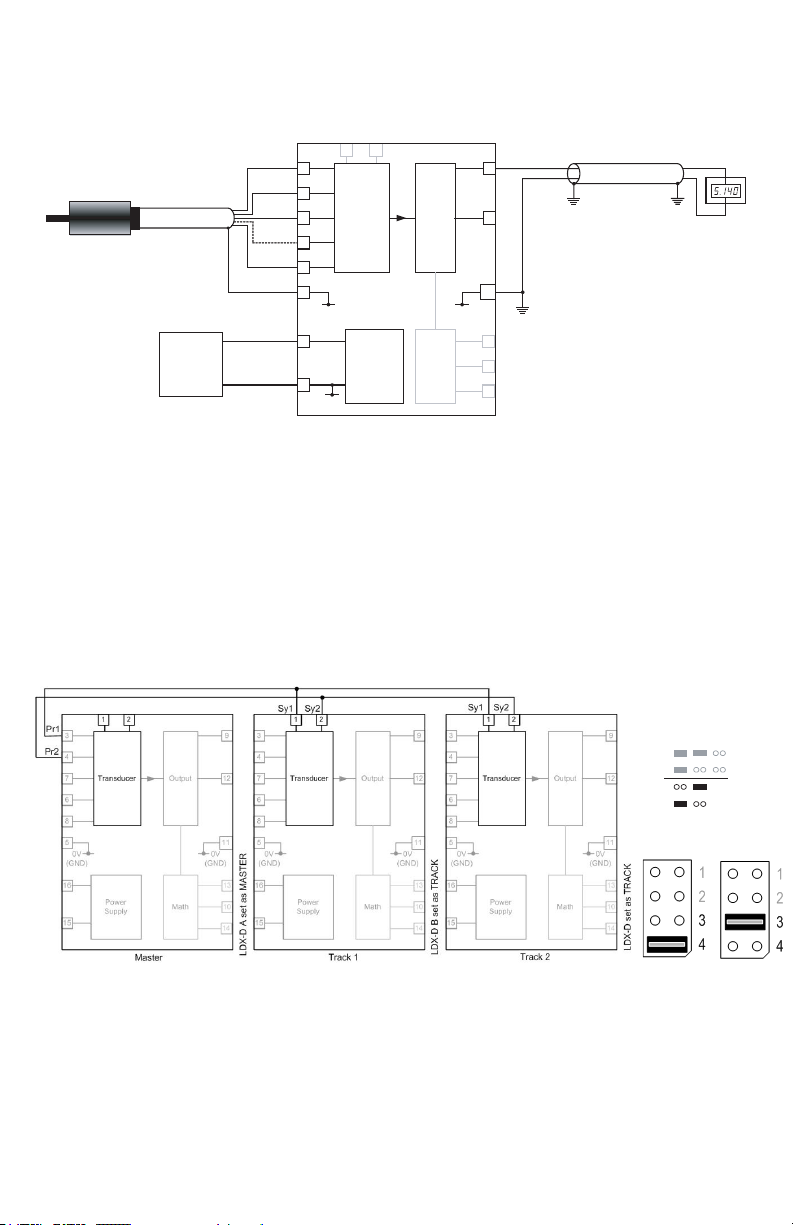
2.0: Installation (continued)
M T
5 10 13
1
2
3
4
Sy1Sy2
Transducer
Power supply
screen
pri1
pri2
sec1
sec2
1 2
3
4
7
CT
Transducer
6
8
5
0V
(GND)
+
16
-
15
0V
(GND)
Power
converter
Output
Math
0V
(GND)
Vout
9
12
11
13
10
14
Ground 1
Ground 2
Min
Mout
Mout#
Voltage
2.11: LDX-D Synchronization
When a system comprises several LDX-D modules, it is possible to synchronise
primary oscillator phases. Synchronization will not be required for most
installations. It is only required when transducers and their cables are installed in
close proximity to each other and there may be electrical interaction or crosstalk between probes. This may be seen as a change in output from one module
when the probe connected to an adjacent module is moved. Even when probes
are installed close to each other, synchronization may not be required as cable
shieldingisgenerallyeective.Ifinteractionsareseen,thecauseisoftenpoor
0Vorscreenconnectionormechanicaleectsbetweenprobeswhenmounted
together.
+
-
PCB Idents
Link Positions
(Primary links not shown)
MASTER
TRACK
Page 12
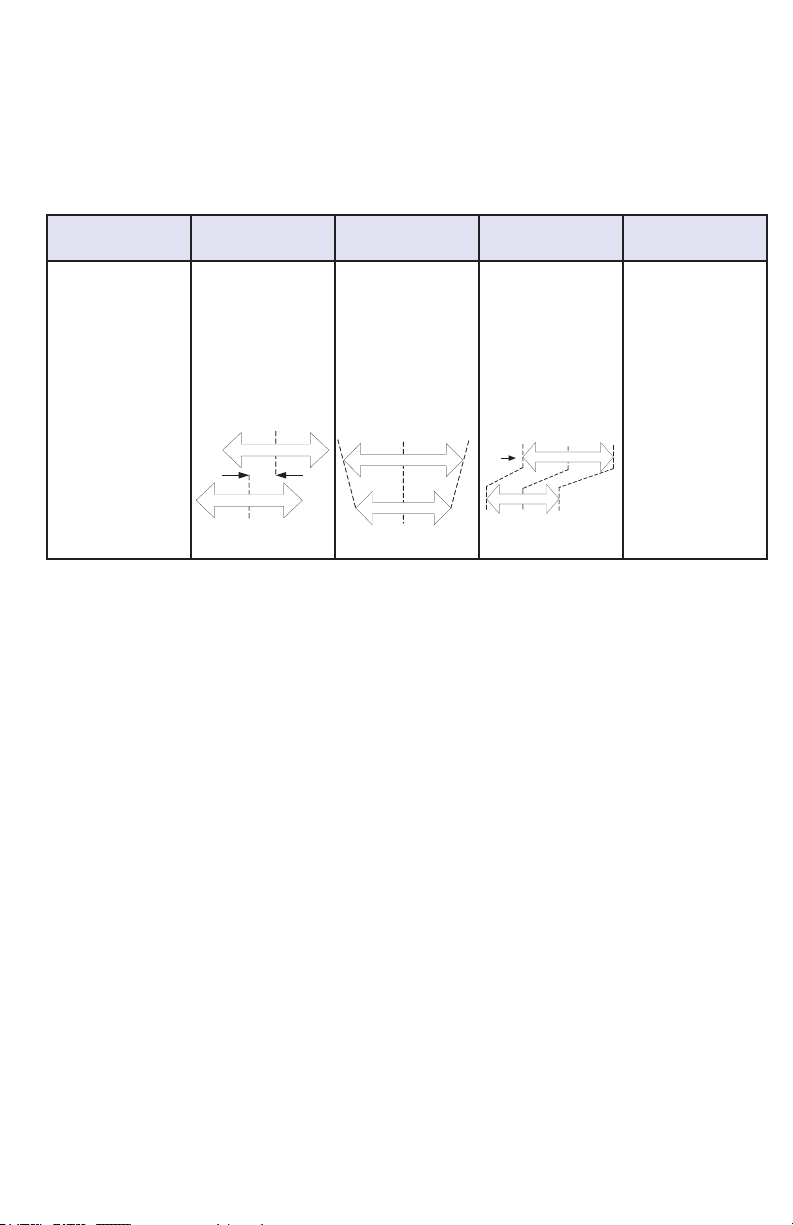
3.0: Setting Up
Null
Zero
transducer
electronics
Zero
-5V+5V
Null
electronics
transducer
Null
+5V0V +10V
electronics
transducer
Shift
zero
3.1: Set-up Summary
This is a set-up summary. A more detailed procedure is included in following
sections but these simple steps describe a typical setting procedure and apply to
most applications. Other procedures may be used as appropriate.
Step 1 Step 2 Step 3 Step 4 Step 5
Set links as
required*
Primary frequency
Transducer load
Initial gain
Bandwidth
Nooset*
No MATH*
• Set LDX-D
output to zero
• Align transducer
null
• Move transducer
to full scale
position
• Set LDX-D
coarseandne
gain
• Addosetif
required
• Set LDX-D
coarseandne
oset
• Final checks
• Repeat steps
2 - 4
to check setting
*If in doubt about initial link position, use the factory setting. Performing initial set-up
withoutosetandMATHoptionsmakesset-upeasier.
Note: If the output polarity is incorrect, reverse the transducer secondary
connections.
For a bi-polar output i.e. ±10 VDC or ±20 mA, follow steps 1 to 3.
For a uni-polar output i.e. 0-10 VDC, 0-20 mA or 4-20 mA, follow steps 1 to 4.
Ineithercase,step5(nalchecks)shouldbefollowedtocompletetheset-up.
3.2: Set-up Procedure
Step 1 - Set-up LDX-D links
If the transducer characteristics are known, set the frequency and input resistance
links as required.
If the transducer is known to be outside the standard sensitivity range, the X1, X2,
X5 or DIV2 links will have to be used. Please refer to section 5.1
Step 2 - Align LDX-D and transducer null
AnyelectricalosetintheLDX-Disremoved.Thetransducerpositionisadjustedso
that transducer and LDX-D nulls are aligned.
Null the LDX-D
1 Put the gain link onto the null position. This puts a temporary short across
thetransducerinputandallowsanyelectronicsosettoberemoved
2 Adjusttheneosetcontroltogiveasnearzerooutputaspractical
Page 13
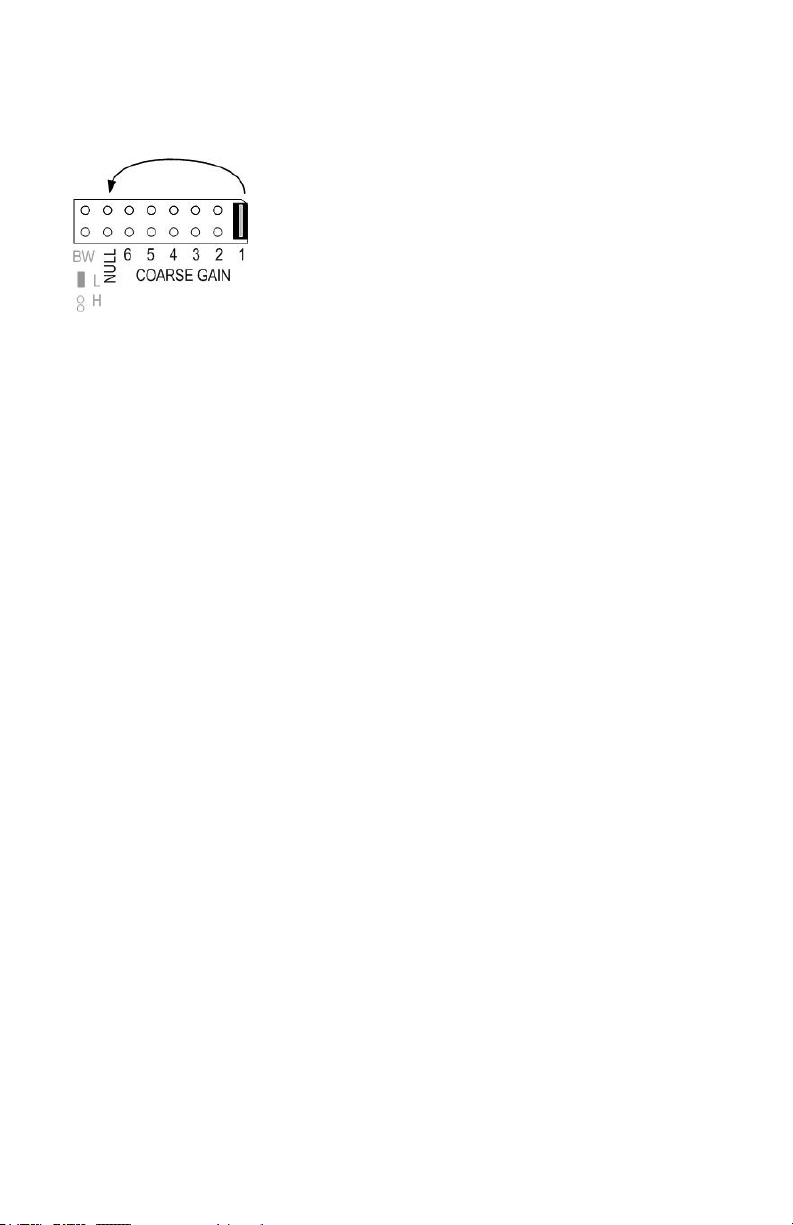
Null the transducer
3 Replace the gain link to the original position
4 Adjust the position of the transducer to give as near zero output as
practical. This is the center of the mechanical range
Ifthetransducercannotbecenteredforpracticalreasons,anosetwillremainwithin
thesystem.Theremaybenoticeableinteractionbetweengainandosetadjustment.
This does not prevent the LDX-D being set-up, although several iterations may be
requiredwhenadjustinggainandoset.Pleaseconsultyoursupplierforguidanceif
required.
Step 3 - Setting bi-polar (±) full scale output
1 Move the transducer to the position where maximum LDX-D output is required
2 If the output polarity is wrong, reverse the transducer secondary connections
terminals 7 & 8). Move the transducer back and re-check the zero position
3 Move the coarse gain link along from position 1 towards position 6 until the
DX-D output is near the required value
4 Adjustthenegaincontroltogivetherequiredoutput
5 The bi-polar output is now set. Proceed to step 5
If a uni-polar output is required proceed to step 4.
Example: ±10 V is required from a ±1 mm transducer. Set the transducer at the +1 mm
position and set the output to +10 V.
Step4-Settinguni-polarfullscaleoutput(addinganoset)
1 Move the transducer to the null position. LDX-D output will be 0 V or 0 mA
2 Applyosetusingthe+VE,-VE,5Vand10Vlinksandadjusttheneoset
ontroltosetprecisely.Bothlinksmaybeusedtogivegreaterosetshift.
roceed to step 5
Example: 0-10 V is required for a ±1 mm transducer. Set the transducer to give ±5 V over
thefullrangeandthen,withthetransduceratnull,add+5Voset.Adjusttheneosetto
give 5 V. When the transducer is moved to the +1 mm position, the output will be +10 V.
Example: 4-20 mA is required for a ±1 mm transducer. Set the transducer to give ±8 mA
overrangeandthen,withthetransduceratnull,add+5V(≈10mA)oset.Adjustthene
osettogive+12mA.Whenthetransducerismovedtothe+1mmposition,theoutput
will be +20 mA.
Step 5 - Final checks
Ensure that calibration is correct by moving the transducer across the required
mechanical range (including the mid position) and checking the calibration points. Fine
adjustments can be made if required.
It may only be possible to set the output accurately at the two calibration points. This is
due to non-linearity within the transducer.
Page 14
4.0: MATH Functions
Power
Supply
15
16
3
7
8
4
6
5
0V
(GND)
Output
11
9
12
0V
(GND)
1 2
Math
Transducer
10
14
13
Min
Mout
Mout#
Min
Mout
Mout#
Vout
Iout
Vout
Iout
Transducer
B
Transducer
A
V
+
-
Power
Supply
15
16
3
7
8
4
6
5
0V
(GND)
Output
11
9
12
0V
(GND)
1 2
Math
Transducer
10
14
13
1
2
3
4
A+B
A-B
LINK FOR
(X)/2
1
2
3
4
1
2
3
4
1
2
3
4
1
2
3
4
1
2
3
4
4.1: MATH Introduction
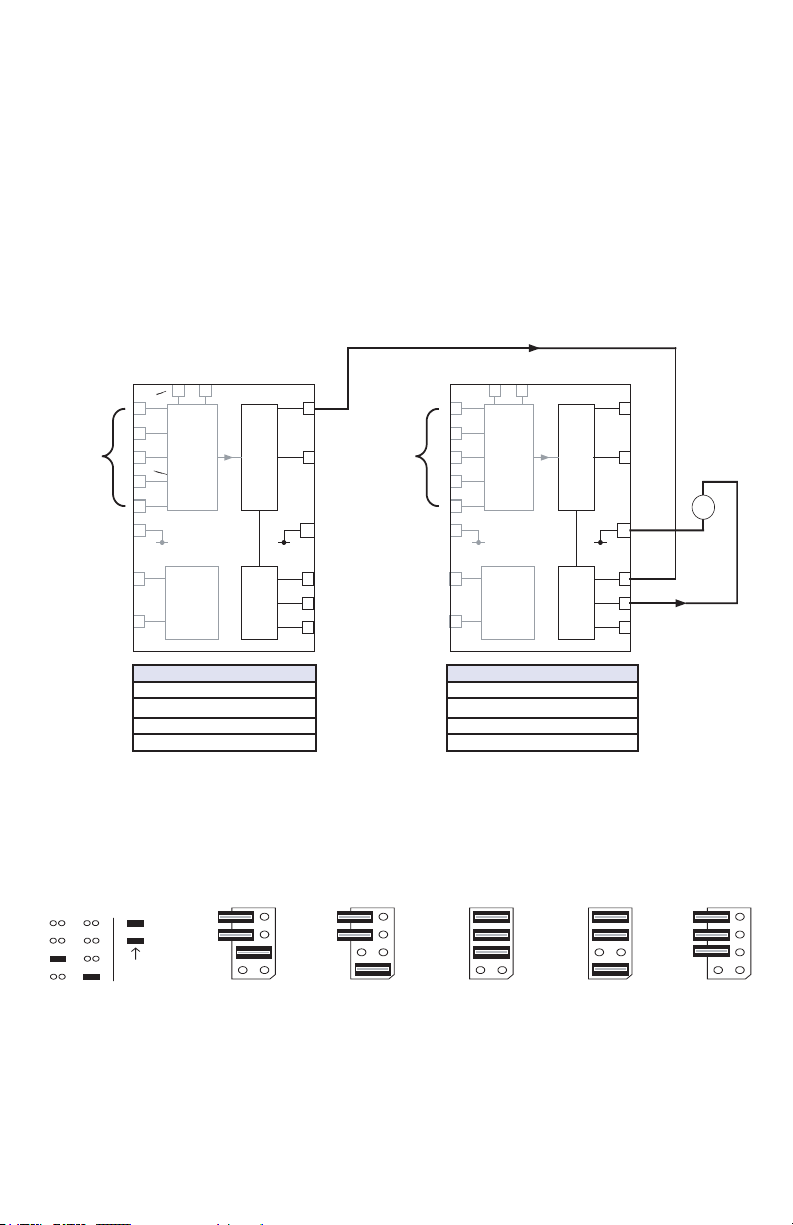
By linking two LDX-D modules, the following analog arithmetic may be
performed: A+B, A-B, (A+B)/2 and (A-B)/2.
The output of LDX-D A, VoutA, is connected to the Min terminal of LDX-D B. The
output of LDX-D B is routed internally to the arithmetic circuits and the result is
available at the Mout terminal.
The inverse of Mout is available as Mout#. Vout, Mout and Mout# may be used
at the same time, however they are not individually adjustable.
LDX-D A
No MATH link setting required
Vout a transducer A position
Mout = Vout
Mout# = 1/Mout = 1/Vout
LDX-D B
Math links set as A-B (example)
Vout a transducer B position
Mout = VoutA - Vout
Mout# = 1/ Mout
B
4.2: MATH Set-up Procedure
Setting up two LDX-D for MATH can become confusing as the output of each
LDX-Dwillaectthenaloutput.Thestepsbelowareguidelinestohelptheset-
up process.
A+B A-B (A+B)/2 (A-B)/2 Mout=Vout
Page 15
4.2: MATH Set-up Procedure (continued)
Step 1 - Requirements
Write down the arithmetic required and the range of outputs likely to be seen. This
will allow the requirement for each individual LDX-D to be determined. Vout of each
LDX-D is used.
Example: ±10 V required for A-B.
If each LDX-D is set to ±10 V, then A-B would calculate to be ±20 V. However, as
this is not possible, each LDX-D must be set to ±5 V or use ±10 V (A-B)/2.
Example: 0-10 V required for A+B.
Set each LDX-D for 0-5 V or set each LDX-D to 0-10 V and use (A+B)/2.
Step 2 - Initial set-up
SetupeachLDX-Dasanindividualmodulerst.
Working around transducer null and having a ±V output will make set-up easier.
Step 3 - Final checks and further comments
Initially each LDX-D Voutmayhavebeensettoanaccuratezerobutanosetmay
still be seen at Mout.ThisisbecauseofosetsinherentwithintheMATHcircuits.
Toremovethisoset,adjustoneoftheVoutosets.Moutosetadjustmentisbest
performed on the LDX-D set for MATH.
5.0: Transducer Sensitivity
5.1: X1, X2, X5 and DIV2 link
The LDX-D compensates for changes in primary signal amplitude by producing
an internal error signal that is the ratio between the primary and secondary
signals. If the transducer output signal is too high or too, low errors may occur that
can degrade the performance of the LDX-D/transducer combination. For these
transducers the X1, X2, X5 or DIV2 input gain link must be used.
Calculating transducer Full Range Output (FRO)
In general, transducer sensitivity is quoted as mV/V/mm where:
mV = output of the transducer V = primary voltage mm = mechanical position of the
transducer from null (usually mid mechanical range).
To calculate the transducer full range output, simply multiply all three together.
Example:
GP911-1 sensitivity is 210 mV/V/mm
LDX-D primary voltage is 3 V
GP911-1 range is ±1 mm
Transducer full range output is 210 x 3 x 1 = 630 mV (0.63 V).
It falls within the standard range.
Set the X2, X5, DIV2 link as shown in the table below:
Transducer Full Range Output Comment Input Gain Link setting
400 mV FRO to 2500 mV FRO Standard range Link ON X1
150 mV FRO to 400 mV FRO Low output transducer Link ON X2
150 mV FRO to 400 mV FRO Very low output transducer Link ON X5
2500 mV FRO to 5000 mV FRO High output transducer
DIV2 - Links X1, X2, X5
parked (ie. all OFF)
Page 16
6.0: Application
Solartron Metrology Ltd.
Bognor Regis PO22 9ST
UK
sales@solartronmetrology.com
www.solartronmetrology.com
DRC
22.5
99.0
111.0
114.5
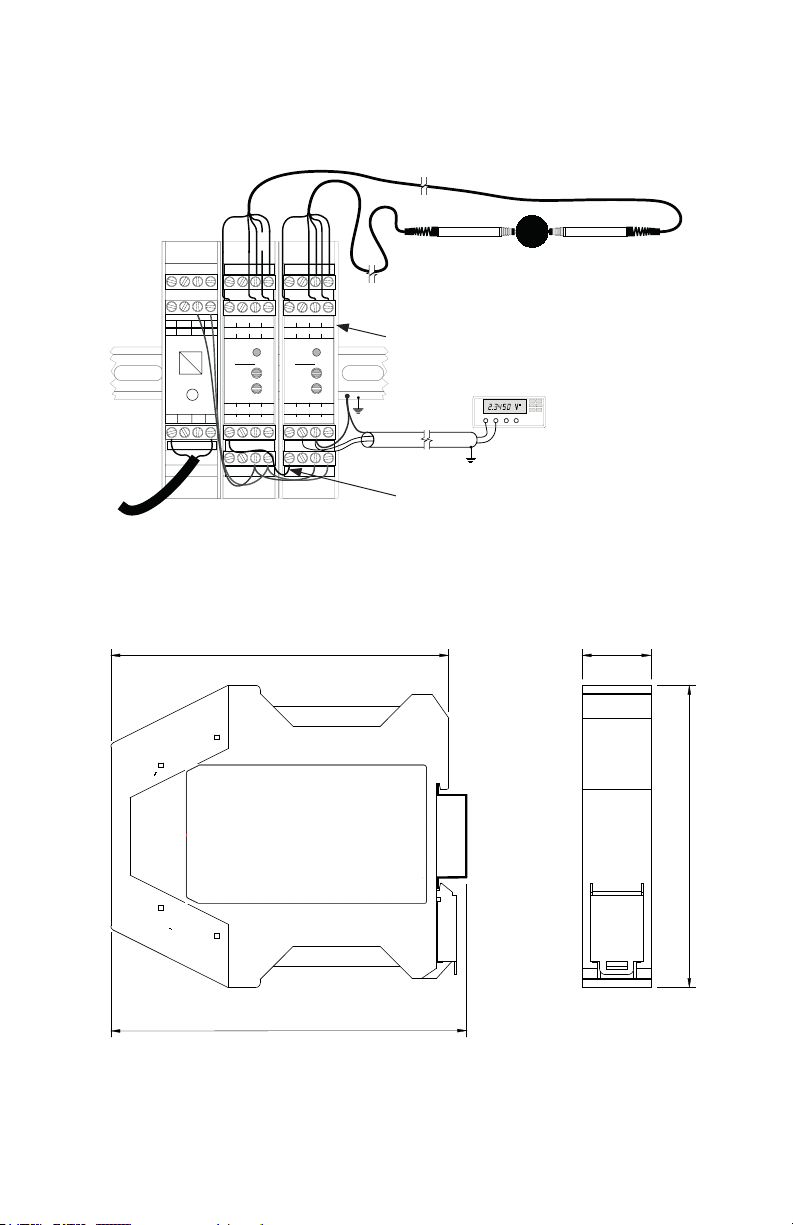
6.1: Application example
1234
1 234
5678
OUT24VDC
-
-
+
+
--
+
Phoenix Contact MINI_PS
+
power supply shown
IN 120– 230 VAC
NC NC
LN
9101112
1234
Mains in
Vout Mout 0V Iout
MinMout#
13
13 14 15 16
5678
1 144
sy1sy2 pri1 pri2
5
scn CT sec1 sec2
Power
FineAdjust
Gain
Offset
output
-+
power
16
9101112
8
5678
sy1sy2 pri1 pri2
5
scn CT sec1 sec2
Power
FineAdjust
Gain
Offset
Vout Mout 0V Iout
output
9912
MinMout
#
power
13
9101112
13 14 15 16
LDX-D A LDX-D B
7.0:Specication
7.1: Mechanical Outline (mm)
LDX-D
8
12
-
+
16
Probe B Probe A
LDX-D B set to A-B
DVM = probe A - Probe B
Chassis/Ground
LDX-D A linked to LDX-D B
Actualinstallationmaydier
depending on requirements.
This is one practical example.
Vdc Vac
AUTO
Idc Iac
AUTO
Hi
Lo GuardHi
V
mA
Page 17
7.0:Specication(continued)
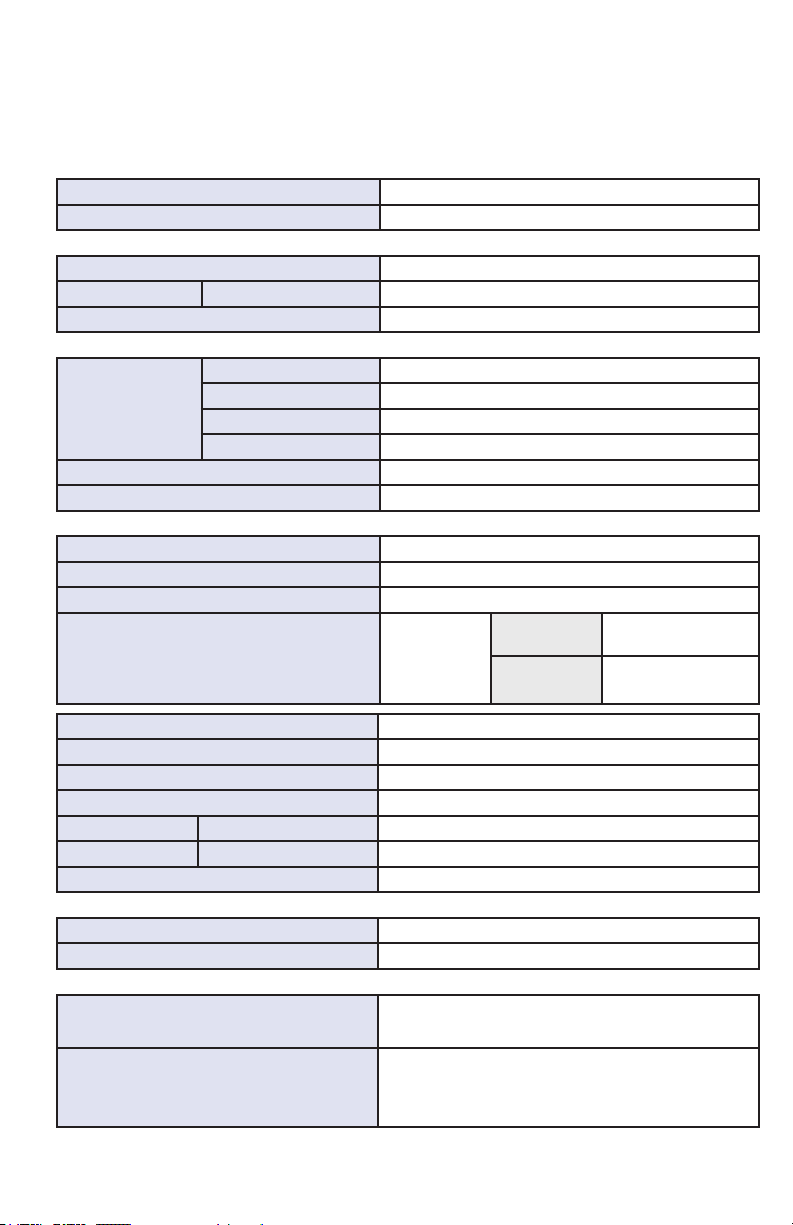
7.2:TechnicalSpecication
Power Requirement
Voltage Range 10 to 30 VDC
Current Range 160 mA at 10 V to 70 mA at 30 V
Transducer Excitation
Primary Voltage 3 V rms nominal
Primary Frequency Link Selectable 5 kHz, 10 kHz or 13 kHz
Primary Current 30 mA max.
Signal Input (Transducer Sensitivity Range)
Standard X1 400 to 2500 mV FRO (in 6 gain ranges)
Gain Range
Link Select
Input Load Resistance 100 kW, 2 kW
Options See note
Signal Output
Voltage Output Up to ±10 VDC
Current Output Up to ±20 mA into 500 W load
Output Ripple <1 mV rms
OutputOset
Special input gain X2 150 to 400 mV FRO
Special input gain X5 55 to 150 mV FRO
Special input gain DIV2 2500 to 5000 mV FRO
1
2
3, 4
Up to 100%
(coarse&ne
adjustment)
Coarse (link
selectable)
Fine (front
panel adjust)
±10 VDC (≈20 mA),
±5 VDC (≈10 mA)
±2.5 VDC (≈5.6 mA)
4
Temp. Co. Gain <0.01% FRO/ºC
Temp.Co.Oset <0.01% FRO/ºC
Warm-up 15 minutes recommended
Linearity <0.1% FRO
Bandwidth (-3 dB) Link Selectable 500 Hz, 1 kHz
Maths Link Selectable A + B, A - B, (A +B)/2, (A - B)/2
Maths Accuracy 0.1% FRO
Environmental
Operational Temperature Range 0 to 60ºC (32 to 140ºF)
Storage Temperature Range -20 to 85ºC (-4 to 185ºF)
Certication
Immunity
BS EN61000-6-2:2001 Immunity for Industrial Envi-
ronments
6
BS EN61000-6-3:2001 Emission for Residential,
Emissions
Commercial
and Light-Industrial Environments
5
6
Page 18
7.0:Specication(continued)
7.2:TechnicalSpecication
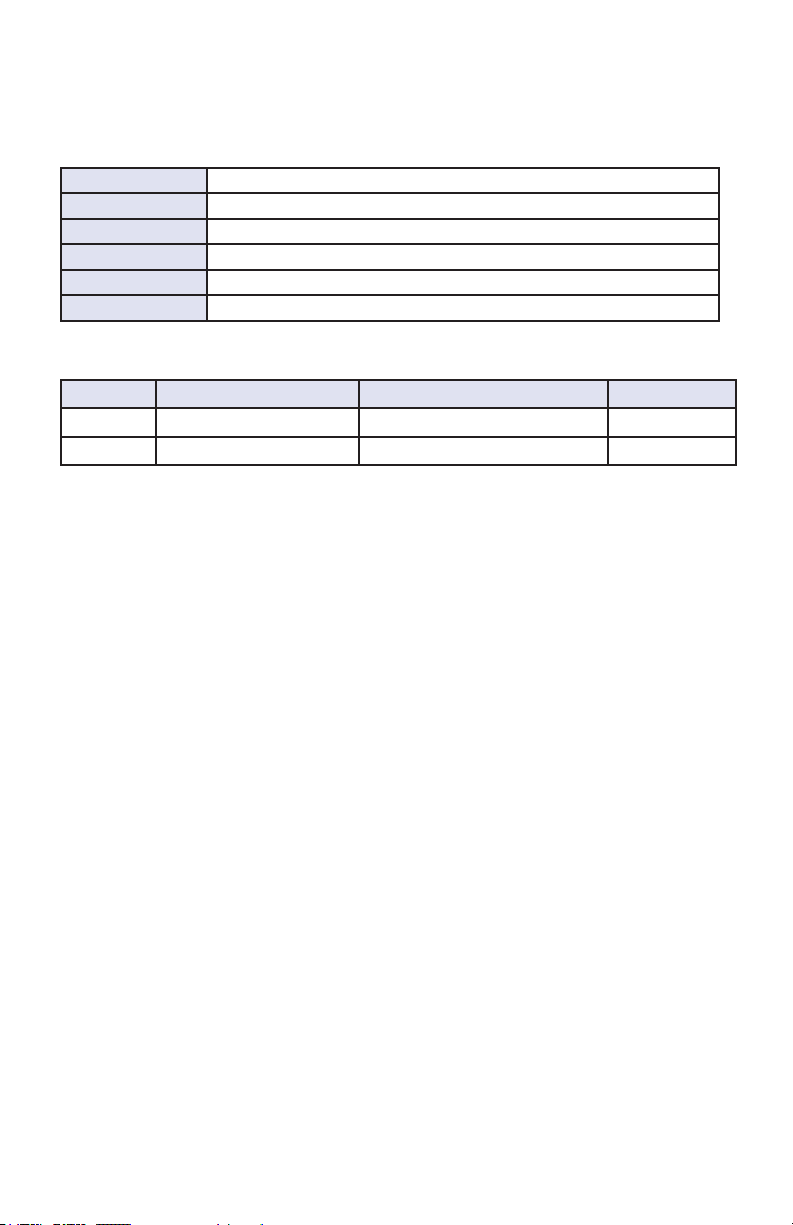
Mechanical and Connections
Transducer Screw terminals
Power Supply Screw terminals
Output Signal Screw terminals
Enclosure (size) 114.5 x 99 x 22.5 mm
Weight 120 g
Material Green polyamide
1
Omega Transducers are calibrated using the following loads:
Standardised (plugged) Non-standardised (unplugged) Displacement
LVDT
Half Bridge
10 kW 100 kW 100 kW
2 kW 1 kW
N/A
When a standard LVDT transducer is connected to LDX-D set for 100 kW, transducer
characteristics will be similar to the non-standardised (unplugged) version of that
transducer. When a non-standardised (unplugged) Half Bridge transducer is connected to LDX-D set for 2 kW, transducer characteristics will be similar to the standardised (plugged) version of that transducer. Any difference in transducer sensitivity
is removed during LDX-D set-up.
Where load resistance is critical, an external resistor may be fitted. If a 10 kW load
is required an additional 11 kW resistor may be used in conjunction with the 100 kW
internal load. This may be connected across the SEC1 (7) and SEC2 (8) terminals. If
a 1 kW load is required, an additional 1 kW resistor may be used.
2
No input options are offered. As connection of transducer is by screw terminal,
additional internal configuration methods are not required. By changing connections
and use of external components, the user can perform:
• Change input polarity • Half Bridge connection • Grounding one side of the input •
Phase correction • Quad resistors.
3
LDX-D can drive into a 1 kWloadbutthisoersnoadvantage. 10-100 kW is recommended.
4
Output range can be adjusted as required anywhere within this range by using a
combination of gain and offset,
for example: ±10 VDC, ±5 VDC, 0-5 VDC, 0-10 VDC, 4-20 mA.
5
Maths requires the use of a second LDX-D. An additional output offset may be
seen at any of the MATH outputs. This is not specified as it is trimmed out during
set-up.
6
The LDX-D is able to comply with the toughest electrical emissions and immunity
regulations. Compliance requires proper installation according to the user manual.
Compliance does not guarantee performance as the installation environment may be
outside of test specification limits. The flexibility of LDX-D means it can be installed
in a variety of ways according to user requirements. Simple installations with short
non-screened cables will meet the lesser light-industrial immunity regulations. Heavy
industrial installations, especially with longer cables, will need more careful installation with screened cables.
Page 19
WARRANTY/DISCLAIMER
OMEGA ENGINEERING, INC. warrants this unit to be free of defects in materials and workmanship for
a period of 13 months from date of purchase. OMEGA’s WARRANTY adds an additional one (1) month
grace period to the normal one (1) year product warranty to cover handling and shipping time. This
ensures that OMEGA’s customers receive maximum coverage on each product.
If the unit malfunctions, it must be returned to the factory for evaluation. OMEGA’s Customer Service
Department will issue an Authorized Return (AR) number immediately upon phone or written request.
Upon examination by OMEGA, if the unit is found to be defective, it will be repaired or replaced at no
charge. OMEGA’s WARRANTY does not apply to defects resulting from any action of the purchaser,
including but not limited to mishandling, improper interfacing, operation outside of design limits,
improper repair, or unauthorized modification. This WARRANTY is VOID if the unit shows evidence
of having been tampered with or shows evidence of having been damaged as a result of excessive
corrosion; or current, heat, moisture or vibration; improper specification; misapplication; misuse or
other operating conditions outside of OMEGA’s control. Components in which wear is not warranted,
include but are not limited to contact points, fuses, and triacs.
OMEGA is pleased to offer suggestions on the use of its various products. However,
OMEGA neither assumes responsibility for any omissions or errors nor assumes liability for any
damages that result from the use of its products in accordance with information provided by OMEGA,
either verbal or written. OMEGA warrants only that the parts manufactured by the company will be as
specified and free of defects. OMEGA MAKES NO OTHER WARRANTIES OR REPRESENTATIONS
OF ANY KIND WHATSOEVER, EXPRESSED OR IMPLIED, EXCEPT THAT OF TITLE, AND ALL
IMPLIED WARRANTIES INCLUDING ANY WARRANTY OF MERCHANTABILITY AND FITNESS
FOR A PARTICULAR PURPOSE ARE HEREBY DISCLAIMED. LIMITATION OF LIABILITY: The
remedies of purchaser set forth herein are exclusive, and the total liability of OMEGA with respect to
this order, whether based on contract, warranty, negligence, indemnification, strict liability or otherwise,
shall not exceed the purchase price of the component upon which liability is based. In no event shall
OMEGA be liable for consequential, incidental or special damages.
CONDITIONS: Equipment sold by OMEGA is not intended to be used, nor shall it be used: (1) as
a “Basic Component” under 10 CFR 21 (NRC), used in or with any nuclear installation or activity; or
(2) in medical applications or used on humans. Should any Product(s) be used in or with any nuclear
installation or activity, medical application, used on humans, or misused in any way, OMEGA assumes
no responsibility as set forth in our basic WARRANTY / DISCLAIMER language, and, additionally,
purchaser will indemnify OMEGA and hold OMEGA harmless from any liability or damage whatsoever
arising out of the use of the Product(s) in such a manner.
Direct all warranty and repair requests/inquiries to the OMEGA Customer Service Department.
RETURN REQUESTS/INQUIRIES
BEFORE RETURNING ANY PRODUCT(S) TO OMEGA, PURCHASER MUST OBTAIN AN
AUTHORIZED RETURN (AR) NUMBER FROM OMEGA’S CUSTOMER SERVICE DEPARTMENT (IN
ORDER TO AVOID PROCESSING DELAYS). The assigned AR number should then be marked on the
outside of the return package and on any correspondence.
The purchaser is responsible for shipping charges, freight, insurance and proper packaging to prevent
breakage in transit.
FOR WARRANTY RETURNS, please have the
following information available BEFORE
contacting OMEGA:
1. Purchase Order number under which
the product was PURCHASED,
2. Model and serial number of the product under
warranty, and
3. Repair instructions and/or specific
problems relative to the product.
OMEGA’s policy is to make running changes, not model changes, whenever an improvement is possible.
This affords our customers the latest in technology and engineering.
OMEGA is a trademark of OMEGA ENGINEERING, INC.
© Copyright 2017 OMEGA ENGINEERING, INC. All rights reserved. This document may not be copied, photocopied, repro-
duced, translated, or reduced to any electronic medium or machine-readable form, in whole or in part, without the prior written
consent of OMEGA ENGINEERING, INC.
FOR NON-WARRANTY REPAIRS,
consult
OMEGA for current repair charges. Have the
following information available BEFORE
contacting OMEGA:
1. Purchase Order number to cover the
COST of the repair,
2. Model and serial number of the product, and
3. Repair instructions and/or specific problems
relative to the product.
Page 20
Where Do I Find Everything I Need for
Process Measurement and Control?
OMEGA…Of Course!
Shop online at omega.com
TEMPERATURE
MU
Thermocouple, RTD & Thermistor Probes, Connectors, Panels & Assemblies
MU
Wire: Thermocouple, RTD & Thermistor
MU
Calibrators & Ice Point References
MU
Recorders, Controllers & Process Monitors
MU
Infrared Pyrometers
PRESSURE, STRAIN AND FORCE
MU
Transducers & Strain Gages
MU
Load Cells & Pressure Gages
MU
Displacement Transducers
MU
Instrumentation & Accessories
FLOW/LEVEL
MU
Rotameters, Gas Mass Flowmeters & Flow Computers
MU
Air Velocity Indicators
MU
Turbine/Paddlewheel Systems
MU
Totalizers & Batch Controllers
pH/CONDUCTIVITY
MU
pH Electrodes, Testers & Accessories
MU
Benchtop/Laboratory Meters
MU
Controllers, Calibrators, Simulators & Pumps
MU
Industrial pH & Conductivity Equipment
DATA ACQUISITION
MU Communications-Based Acquisition Systems
MU Data Logging Systems
MU Wireless Sensors, Transmitters, & Receivers
MU Signal Conditioners
MU Data Acquisition Software
HEATERS
MU
Heating Cable
MU
Cartridge & Strip Heaters
MU
Immersion & Band Heaters
MU
Flexible Heaters
MU
Laboratory Heaters
ENVIRONMENTAL
MONITORING AND CONTROL
MU
Metering & Control Instrumentation
MU
Refractometers
MU
Pumps & Tubing
MU
Air, Soil & Water Monitors
MU
Industrial Water & Wastewater Treatment
MU
pH, Conductivity & Dissolved Oxygen Instruments
M-4346/0218
 Loading...