

Page 1

NEXCOM International Co., Ltd.
Mobile Computing Solutions
Vehicle Telematics Computer
VTC 100
User Manual
NEXCOM International Co., Ltd.
Published March 2014
www.nexcom.com
Page 2
Contents
Contents
Preface
Copyright ............................................................................................. iv
Disclaimer ............................................................................................. iv
Acknowledgements .............................................................................. iv
Regulatory Compliance Statements ....................................................... iv
Declaration of Conformity ...................................................................... iv
RoHS Compliance ................................................................................... v
Warranty and RMA ................................................................................ vi
Safety Information ................................................................................vii
Installation Recommendations ................................................................vii
Safety Precautions .................................................................................viii
Technical Support and Assistance ........................................................... ix
Conventions Used in this Manual ........................................................... ix
Global Service Contact Information ......................................................... x
Package Contents ..................................................................................xii
Ordering Information ............................................................................xiii
Chapter 1: Product Introduction
Overview ................................................................................................1
Hardware Specifications ..........................................................................2
Getting to Know VTC 100 ......................................................................3
Front Panel ...........................................................................................3
Rear Panel ............................................................................................3
Mechanical Dimensions ...........................................................................5
Chapter 2: Jumpers and Connectors
Before You Begin ................................................................................... 6
Precautions ............................................................................................6
Jumper ...................................................................................................7
Locations of the Jumpers and Connectors ............................................... 8
Jumper and DIP Switch Settings ..............................................................9
MCU Bootloader Power Select .............................................................. 9
DIP Switch ............................................................................................ 9
Connectors ........................................................................................... 11
MCU Bootloader Pin Definition ........................................................... 11
Debug Ports .......................................................................................11
VBAT CONN .......................................................................................12
USB Ports ...........................................................................................12
WIFI & BT Connector ..........................................................................13
GPS Connector ................................................................................... 13
Mini PCI-E Connector .........................................................................14
SIM Card Connector ...........................................................................15
Micro SD Connector ...........................................................................15
CAN Module Connector ..................................................................... 16
POWER INPUT (CN1) ........................................................................... 16
Power Button .....................................................................................17
Reset Button ....................................................................................... 17
Power On & SD Active LED .................................................................18
Line-out and Mic-in Connectors .......................................................... 18
Power On & SD Active LED .................................................................19
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
ii
VTC 100 User Manual
Page 3
Contents
VGA connector ................................................................................... 19
Standard RS232 Interface ...................................................................20
RS485 connector ................................................................................ 20
GPIO connector .................................................................................. 21
Chapter 3: System Setup
Removing the Chassis Cover .................................................................22
Installing a WWAN Module ...................................................................24
WWAN Dial-up Setting .........................................................................25
Activesync Setting ................................................................................. 29
Appendix A: CAN Module Setup and Command..31
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
iii
VTC 100 User Manual
Page 4
Preface
Preface
Copyright
This publication, including all photographs, illustrations and software, is
protected under international copyright laws, with all rights reserved. No
part of this manual may be reproduced, copied, translated or transmitted
in any form or by any means without the prior written consent from
NEXCOM International Co., Ltd.
Disclaimer
The information in this document is subject to change without prior notice
and does not represent commitment from NEXCOM International Co., Ltd.
However, users may update their knowledge of any product in use by
constantly checking its manual posted on our website: http://www.nexcom.
com. NEXCOM shall not be liable for direct, indirect, special, incidental, or
consequential damages arising out of the use of any product, nor for any
infringements upon the rights of third parties, which may result from such
use. Any implied warranties of merchantability or fitness for any particular
purpose is also disclaimed.
Acknowledgements
VTC 100 is a trademark of NEXCOM International Co., Ltd. All other product
names mentioned herein are registered trademarks of their respective owners.
Regulatory Compliance Statements
This section provides the FCC compliance statement for Class A devices and
describes how to keep the system CE compliant.
Declaration of Conformity
FCC
This equipment has been tested and verified to comply with the limits for
a Class A digital device, pursuant to Part 15 of FCC Rules. These limits are
designed to provide reasonable protection against harmful interference when
the equipment is operated in a commercial environment. This equipment
generates, uses, and can radiate radio frequency energy and, if not installed
and used in accordance with the instructions, may cause harmful interference
to radio communications. Operation of this equipment in a residential area
(domestic environment) is likely to cause harmful interference, in which
case the user will be required to correct the interference (take adequate
measures) at their own expense.
CE
The product(s) described in this manual complies with all applicable European Union (CE) directives if it has a CE marking. For computer systems to
remain CE compliant, only CE-compliant parts may be used. Maintaining CE
compliance also requires proper cable and cabling techniques.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
iv
VTC 100 User Manual
Page 5
Preface
RoHS Compliance
NEXCOM RoHS Environmental Policy and Status Update
NEXCOM is a global citizen for building the digital
infrastructure. We are committed to providing green
products and services, which are compliant with European Union RoHS (Restriction on Use of Hazardous
Substance in Electronic Equipment) directive 2002/95/
EU, to be your trusted green partner and to protect
our environment.
RoHS restricts the use of Lead (Pb) < 0.1% or 1,000ppm, Mercury (Hg)
< 0.1% or 1,000ppm, Cadmium (Cd) < 0.01% or 100ppm, Hexavalent
Chromium (Cr6+) < 0.1% or 1,000ppm, Polybrominated biphenyls (PBB) <
0.1% or 1,000ppm, and Polybrominated diphenyl Ethers (PBDE) < 0.1% or
1,000ppm.
In order to meet the RoHS compliant directives, NEXCOM has established an
engineering and manufacturing task force in to implement the introduction
of green products. The task force will ensure that we follow the standard
NEXCOM development procedure and that all the new RoHS components
and new manufacturing processes maintain the highest industry quality levels for which NEXCOM are renowned.
How to recognize NEXCOM RoHS Products?
For existing products where there are non-RoHS and RoHS versions, the suffix “(LF)” will be added to the compliant product name.
All new product models launched after January 2006 will be RoHS compliant. They will use the usual NEXCOM naming convention.
The model selection criteria will be based on market demand. Vendors and
suppliers will ensure that all designed components will be RoHS compliant.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
v
VTC 100 User Manual
Page 6
Preface
Warranty and RMA
NEXCOM Warranty Period
NEXCOM manufactures products that are new or equivalent to new in accordance with industry standard. NEXCOM warrants that products will be
free from defect in material and workmanship for 2 years, beginning on the
date of invoice by NEXCOM. HCP series products (Blade Server) which are
manufactured by NEXCOM are covered by a three year warranty period.
NEXCOM Return Merchandise Authorization (RMA)
? Customers shall enclose the “NEXCOM RMA Service Form” with the re-
turned packages.
? Customers must collect all the information about the problems encoun-
tered and note anything abnormal or, print out any on-screen messages,
and describe the problems on the “NEXCOM RMA Service Form” for the
RMA number apply process.
? Customers can send back the faulty products with or without accessories
(manuals, cable, etc.) and any components from the card, such as CPU
and RAM. If the components were suspected as part of the problems,
please note clearly which components are included. Otherwise, NEXCOM
is not responsible for the devices/parts.
? Customers are responsible for the safe packaging of defective products,
making sure it is durable enough to be resistant against further damage and deterioration during transportation. In case of damages occurred
during transportation, the repair is treated as “Out of Warranty.”
? Any products returned by NEXCOM to other locations besides the cus-
tomers’ site will bear an extra charge and will be billed to the customer.
Repair Service Charges for Out-of-Warranty Products
NEXCOM will charge for out-of-warranty products in two categories, one is
basic diagnostic fee and another is component (product) fee.
System Level
? Component fee: NEXCOM will only charge for main components such as
SMD chip, BGA chip, etc. Passive components will be repaired for free,
ex: resistor, capacitor.
? Items will be replaced with NEXCOM products if the original one cannot
be repaired. Ex: motherboard, power supply, etc.
? Replace with 3
? If RMA goods can not be repaired, NEXCOM will return it to the customer
without any charge.
rd
party products if needed.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
vi
VTC 100 User Manual
Page 7
Preface
Board Level
? Component fee: NEXCOM will only charge for main components, such
as SMD chip, BGA chip, etc. Passive components will be repaired for free,
ex: resistors, capacitors.
If RMA goods can not be repaired, NEXCOM will return it to the customer
without any charge.
Warnings
Read and adhere to all warnings, cautions, and notices in this guide and
the documentation supplied with the chassis, power supply, and accessory
modules. If the instructions for the chassis and power supply are inconsistent
with these instructions or the instructions for accessory modules, contact
the supplier to find out how you can ensure that your computer meets
safety and regulatory requirements.
Cautions
Electrostatic discharge (ESD) can damage system components. Do the described procedures only at an ESD workstation. If no such station is available, you can provide some ESD protection by wearing an antistatic wrist
strap and attaching it to a metal part of the computer chassis.
Safety Information
Before installing and using the device, note the following precautions:
▪ When replacing parts, ensure that your service technician uses parts spec-
ified by the manufacturer.
▪ Avoid using the system near water, in direct sunlight, or near a heating
device.
▪ The load of the system unit does not solely rely for support from the
rackmounts located on the sides. Firm support from the bottom is highly
necessary in order to provide balance stability.
The computer is provided with a battery-powered real-time clock circuit.
There is a danger of explosion if battery is incorrectly replaced. Replace only
with the same or equivalent type recommended by the manufacturer. Discard used batteries according to the manufacturer’s instructions.
Installation Recommendations
Ensure you have a stable, clean working environment. Dust and dirt can get
into components and cause a malfunction. Use containers to keep small
components separated.
Adequate lighting and proper tools can prevent you from accidentally damaging the internal components. Most of the procedures that follow require
only a few simple tools, including the following:
• A Philips screwdriver
• A flat-tipped screwdriver
• A grounding strap
• An anti-static pad
▪ Read all instructions carefully.
▪ Do not place the unit on an unstable surface, cart, or stand.
▪ Follow all warnings and cautions in this manual.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
Using your fingers can disconnect most of the connections. It is recommended that you do not use needlenose pliers to disconnect connections as
these can damage the soft metal or plastic parts of the connectors.
vii
VTC 100 User Manual
Page 8
Preface
Safety Precautions
1. Read these safety instructions carefully.
2. Keep this User Manual for later reference.
3. Disconnect this equipment from any AC outlet before cleaning. Use a
damp cloth. Do not use liquid or spray detergents for cleaning.
4. For plug-in equipment, the power outlet socket must be located near
the equipment and must be easily accessible.
5. Keep this equipment away from humidity.
6. Put this equipment on a stable surface during installation. Dropping it
or letting it fall may cause damage.
7. Do not leave this equipment in either an unconditioned environment
or in a above 40
ment.
8. The openings on the enclosure are for air convection to protect the
equipment from overheating. DO NOT COVER THE OPENINGS.
9. Make sure the voltage of the power source is correct before connecting the equipment to the power outlet.
10. Place the power cord in a way so that people will not step on it. Do
not place anything on top of the power cord. Use a power cord that
has been approved for use with the product and that it matches the
voltage and current marked on the product’s electrical range label. The
voltage and current rating of the cord must be greater than the voltage and current rating marked on the product.
o
C storage temperature as this may damage the equip-
12. If the equipment is not used for a long time, disconnect it from the
power source to avoid damage by transient overvoltage.
13. Never pour any liquid into an opening. This may cause fire or electrical
shock.
14. Never open the equipment. For safety reasons, the equipment should
be opened only by qualified service personnel.
15. If one of the following situations arises, get the equipment checked by
service personnel:
a. The power cord or plug is damaged.
b. Liquid has penetrated into the equipment.
c. The equipment has been exposed to moisture.
d. The equipment does not work well, or you cannot get it to work
according to the user’s manual.
e. The equipment has been dropped and damaged.
f. The equipment has obvious signs of breakage.
16. Do not place heavy objects on the equipment.
17. The unit uses a three-wire ground cable which is equipped with a third
pin to ground the unit and prevent electric shock. Do not defeat the
purpose of this pin. If your outlet does not support this kind of plug,
contact your electrician to replace your obsolete outlet.
18. CAUTION: DANGER OF EXPLOSION IF BATTERY IS INCORRECTLY REPLACED. REPLACE ONLY WITH THE SAME OR EQUIVALENT TYPE RECOMMENDED BY THE MANUFACTURER. DISCARD USED BATTERIES
ACCORDING TO THE MANUFACTURER’S INSTRUCTIONS.
11. All cautions and warnings on the equipment should be noted.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
19. The computer is provided with CD drives that comply with the appropriate safety standards including IEC 60825.
viii
VTC 100 User Manual
Page 9
Preface
Technical Support and Assistance
1. For the most updated information of NEXCOM products, visit NEXCOM’s
website at www.nexcom.com.
2. For technical issues that require contacting our technical support team or
sales representative, please have the following information ready before
calling:
– Product name and serial number
– Detailed information of the peripheral devices
– Detailed information of the installed software (operating system,
version, application software, etc.)
– A complete description of the problem
– The exact wordings of the error messages
Warning!
1. Handling the unit: carry the unit with both hands and handle it with
care.
2. Maintenance: to keep the unit clean, use only approved cleaning products or clean with a dry cloth.
3. CompactFlash: Turn off the unit’s power before inserting or removing a
CompactFlash storage card.
Conventions Used in this Manual
Warning: Information about certain situations, which if not observed, can cause personal injury. This will prevent injury to yourself when performing a task.
Caution: Information to avoid damaging components or losing
data.
Note: Provides additional information to complete a task easily.
Battery - Safety Measures
Caution
• Risk of explosion if battery is replaced by an incorrect type.
• Dispose of used batteries according to the instructions.
Safety Warning
This equipment is intended for installation in a Restricted Access
Location only.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
Resetting the Date and Time
Note: Remember to reset the date and time upon receiving the
product. You can set them in the AMI BIOS. Refer to chapter 4 for
more information.
ix
VTC 100 User Manual
Page 10
Preface
Global Service Contact Information
Headquarters
NEXCOM International Co., Ltd.
15F, No. 920, Chung-Cheng Rd.,
Zhonghe District, New Taipei City, 23586,
Taiwan, R.O.C.
Tel: +886-2-8226-7786
Fax: +886-2-8226-7782
www.nexcom.com
America
USA
NEXCOM USA
2883 Bayview Drive,
Fremont CA 94538, USA
Tel: +1-510-656-2248
Fax: +1-510-656-2158
Email: [email protected]
www.nexcom.com
Asia
Taiwan
Central Taiwan Office
16F, No.250, Sec. 2, Chongde Rd.,
Beitun Dist., Taichung City 406, R.O.C.
Tel: +886-4-2249-1179
Fax: +886-4-2249-1172
Email: [email protected]
www.nexcom.com.tw
Japan
NEXCOM Japan
9F, Tamachi Hara Bldg.,
4-11-5, Shiba Minato-ku,
Tokyo, 108-0014, Japan
Tel: +81-3-5419-7830
Fax: +81-3-5419-7832
Email: [email protected]
www.nexcom-jp.com
China
NEXCOM China
2F, Block 4, Venus Plaza, Bldg. 21,
ZhongGuanCun Software Park, No. 8,
Dongbeiwang West Rd., Haidian District,
Beijing, 100193, China
Tel: +86-10-8282-6599
Fax: +86-10-8282-5955
Email: [email protected]
www.nexcom.cn
Shanghai Office
Room 603/604, Huiyinmingzun Plaza Bldg., 1,
No.609, Yunlin East Rd.,
Shanghai, 200062, China
Tel: +86-21-5278-5868
Fax: +86-21-3251-6358
Email: [email protected]
www.nexcom.cn
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
x
VTC 100 User Manual
Page 11
Preface
Shenzhen Office
Room1707, North Block, Pines Bldg.,
No.7 Tairan Rd., Futian Area,
Shenzhen, 518040, China
Tel: +86-755-8332-7203
Fax: +86-755-8332-7213
Email: [email protected]
www.nexcom.cn
Wuhan Office
1-C1804/1805, Mingze Liwan,
No. 519 South Luoshi Rd.,
Hongshan District,
Wuhan, 430070, China
Tel: +86-27-8722-7400
Fax: +86-27-8722-7400
Email: [email protected]
www.nexcom.cn
Chengdu Office
9F, Shuxiangxie, Xuefu Garden,
No.12 Section 1, South Yihuan Rd.,
Chengdu, 610061, China
Tel: +86-28-8523-0186
Fax: +86-28-8523-0186
Email: [email protected]
www.nexcom.cn
Europe
Italy
NEXCOM ITALIA S.r.l
Via Gaudenzio Ferrari 29,
21047 Saronno (VA), Italia
Tel: +39 02 9628 0333
Fax: +39 02 9286 9215
Email: [email protected]
www.nexcomitalia.it
United Kingdom
NEXCOM EUROPE
10 Vincent Avenue,
Crownhill Business Centre,
Milton Keynes, Buckinghamshire,
MK8 0AB, United Kingdom
Tel: +44-1908-267121
Fax: +44-1908-262042
Email: [email protected]
www.nexcom.eu
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
xi
VTC 100 User Manual
Page 12
Preface
Package Contents
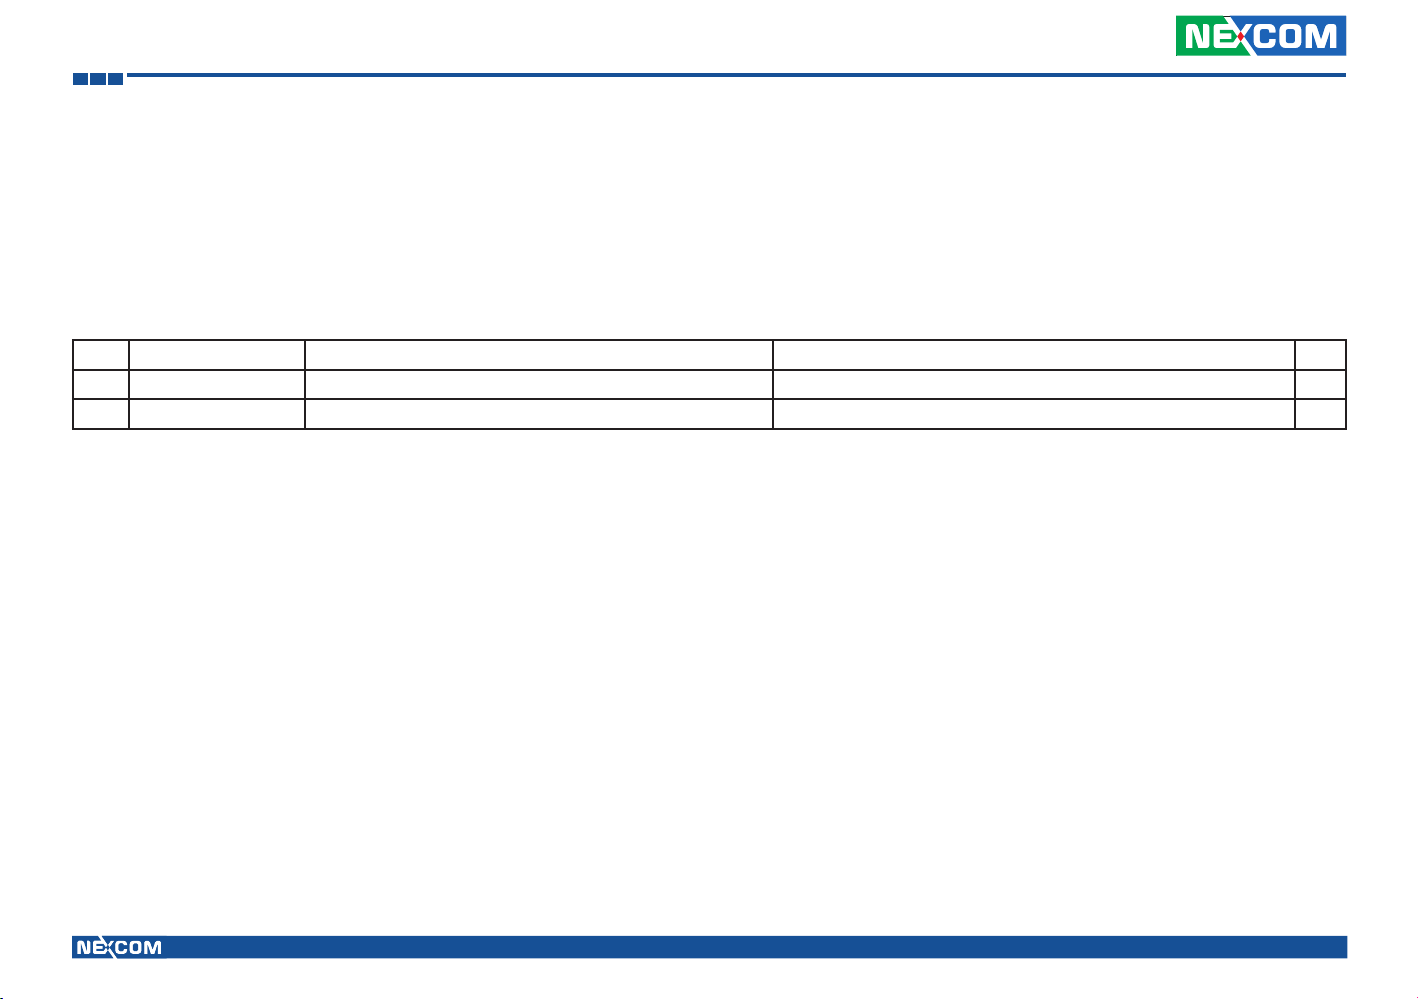
Before continuing, verify that the VTC 100 package that you received is complete. Your VTC 100 package should have all the items listed in the following
table.
Item P/N Name Specification Qty
1 4NCPM00302X00 Power connector TERMINAL BLOCKS 3P PHOENIX CONTACT:1777992 1
2 602DCD0644X00 CD DRIVER 1
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
xii
VTC 100 User Manual
Page 13
Preface
Ordering Information
The following provides ordering information for VTC 100.
• VTC 100-A0E (P/N: TBD)
- ARM® Cortex™-A8 720MHz Processor with 256MB DDR2 and WEC7
system
• VTC 100-A1E (P/N: 10V00010000X0)
- ARM® Cortex™-A8 720MHz Processor with 256MB DDR2, GPS and
WEC7 system
• VTC 100-A1U (P/N: 10V00010001X0)
- ARM® Cortex™-A8 720MHz Processor with 256MB DDR2, GPS and
Linux Ubuntu
• VTC 100-A5E (P/N: TBD)
- ARM® Cortex™-A8 720MHz Processor with 256MB DDR2, GPS, CAN
bus and WEC7 system
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
xiii
VTC 100 User Manual
Page 14
Chapter 1: Product Introduction
Chapter 1: Product Introduction
Overview
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
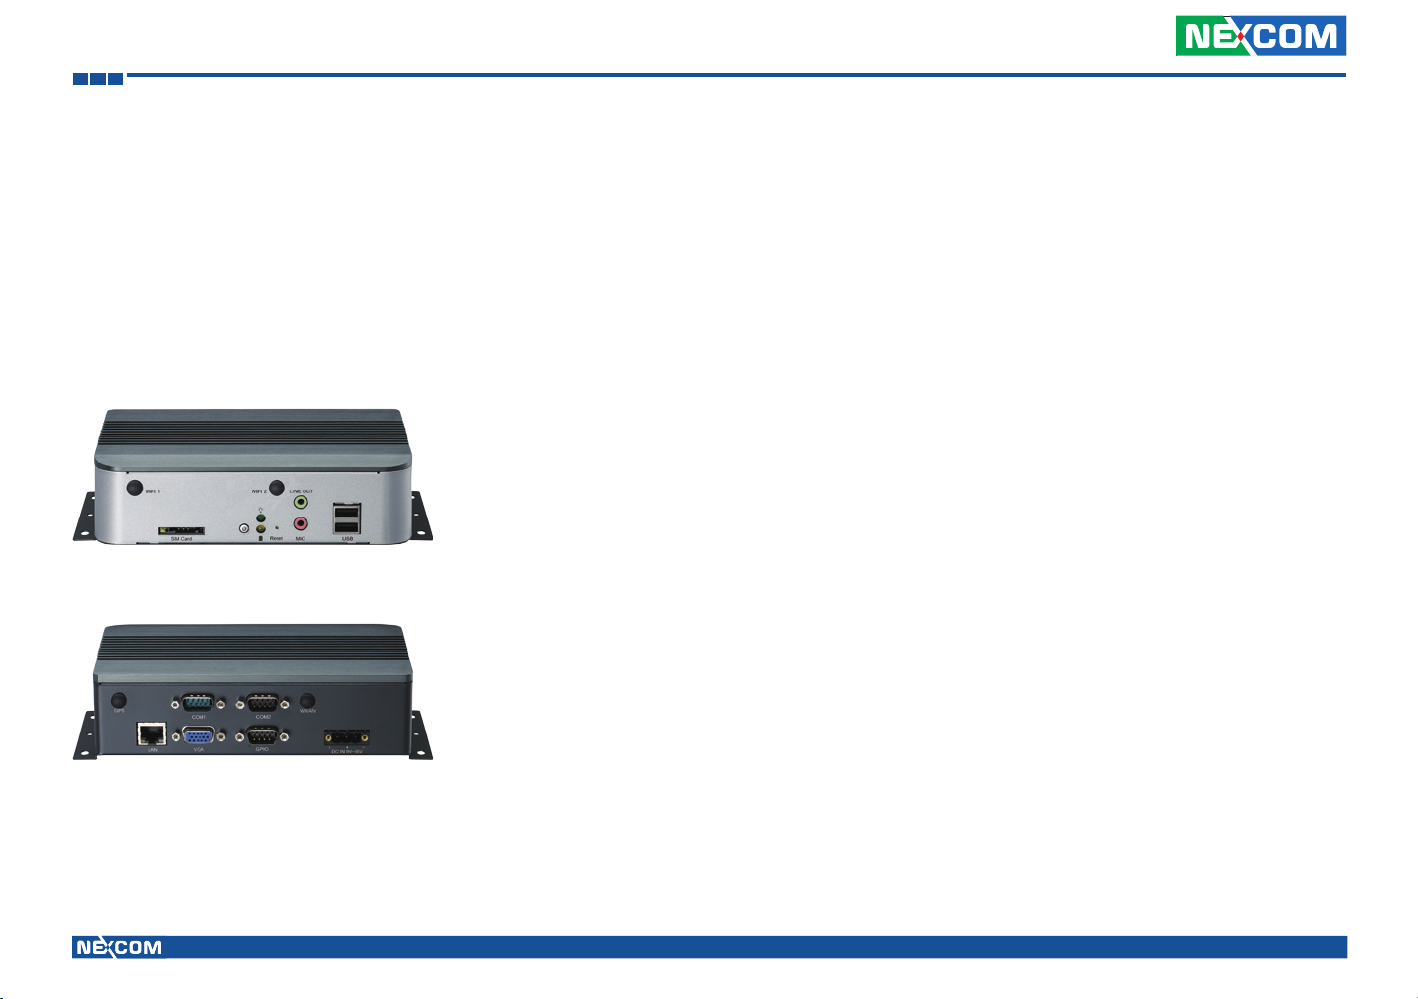
VTC 100 Front View
VTC 100 Rear View
Key Features
• Compact and fanless design
• ARM Cortex™-A8 Processor with 720MHz frequency
• Variety wireless communication options
• Built-in CAN Bus V2.0b; optional support for J1939/J1708
• Wide range DC input from 9~ 36V
• Smart power management and low voltage protection
• Operating System Support WEC 7 and Linux 3.1 driver
1
VTC 100 User Manual
Page 15
Chapter 1: Product Introduction
Hardware Specifications
MPU
• ARM Cortex™-A8 Processor with 720MHz frequency
Memory
• On-board DDR2 256MB
Expansion
• 1x CAN Bus module with J1939/J1708 for option
• 1x Mini-PCIe socket (USB) x 1 for WWAN option
• 1x Bundle GPS module
I/O Interface-Front
• 2x USB 2.0 host type A connector
• 1x Line-out, 1 x Mic-in
• 1x System reset button
• 2x LED’s for power, storage
• 1x Power button
• 1x SIM card socket
• 4x Antenna hole reserved for SMA-type antenna connector (WWAN/
WLAN)
I/O Interface-Rear
• 1x 9~36VDC input with Ignition and 6W typical power consumption
• 1x DB9 RS-232 (COM1)
• 1x DB9 RS-485 (COM2)
• 1x DB9 female connector for 3GPI and 3GPO
• 1x DB15 VGA
• 1x RJ45 with LEDs for 10/ 100/ 1000Mbps Ethernet
• 1x SMA-type GPS antenna connector
• 1x Antenna hole reserved for SMA-type antenna connector (WWAN/
WLAN)
Expandable Storage
• Micro SDHC Slot (Bundle with 4GB)
Power Management
• Selectable boot-up & shut-down voltage for low power protection
• HW design ready for 8-level delay time on/off at user’s self configuration
• Power on/off ignition, software detectable
Operating System
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
• Windows Embedded Compact 7
• Linux 3.2
2
VTC 100 User Manual
Page 16
Chapter 1: Product Introduction
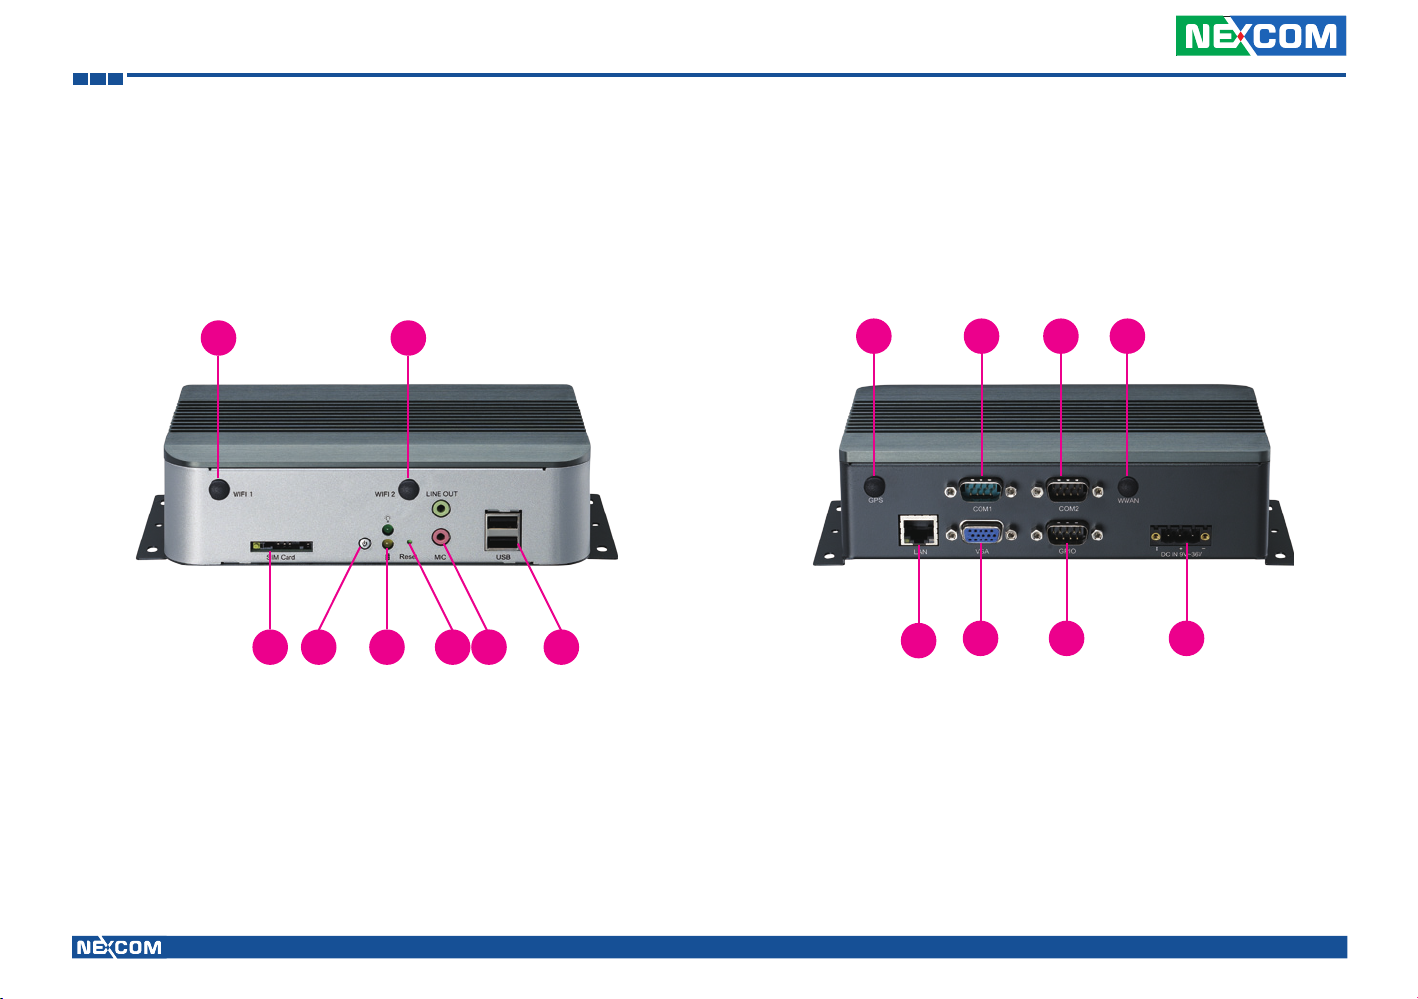
Getting to Know VTC 100
Front Panel Rear Panel
7
1
2 3 4 5 6
7
7 8 9 7
10
11 12 13
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
3
VTC 100 User Manual
Page 17
Chapter 1: Product Introduction
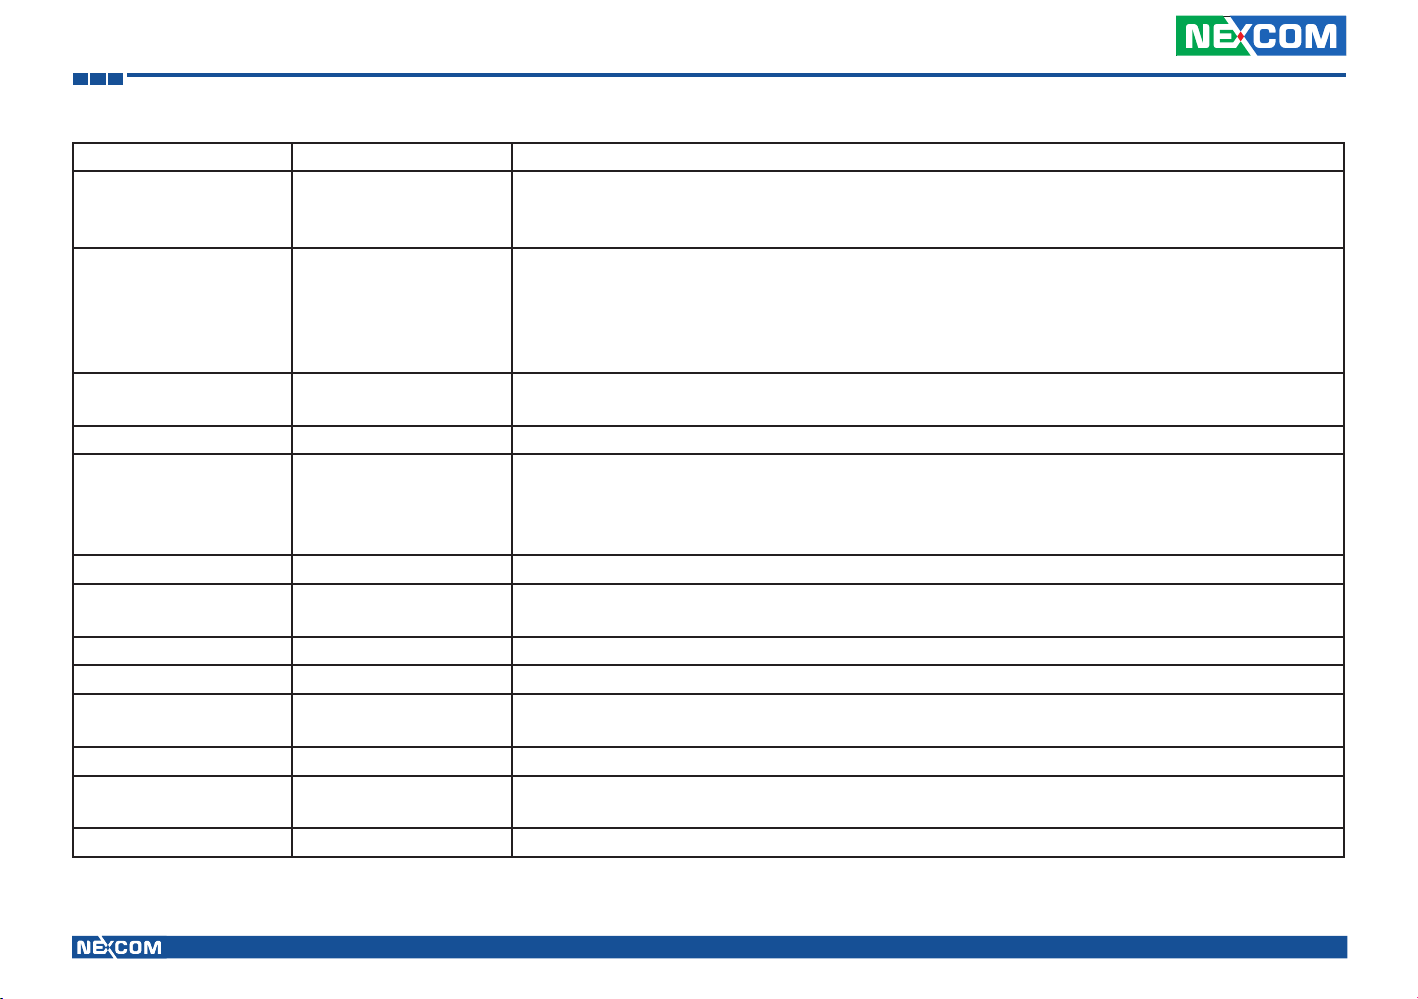
Item Function Description
1 SIM Card Slot
2 Power Button
3 LED indicator
4 Reset Button Press this button to restart VTC.
5 Audio
6 USB Port The two USB ports are compliant with USB2.0 specifications.
7 Antenna Holes
8 COM1 RS-232 connector
9 COM2 RS-485 connector
10 LAN Port
11 VGA Port The DB15 VGA port supports resolutions of 640 x 480 and 800 x 600
12 GPIO
13 Power Input Connector 9 ~ 36VDC power Input.
VTC can be internally integrated with a 3.5G Mini Card module. The SIM card bracket is on the carrier board.
When using the GPRS/UMTS/ HSDPA function, insert the SIM card into the SIM card socket. Make sure to turn
off VTC before inserting the SIM card.
When the ignition is from “low” to “high”, VTC will turn on automatically.
When the ignition is “high”, press the power button 5~6 secs to turn off VTC.
When the ignition is “high”, VTC has been turned off, press the power button 1~2 secs to turn on the system.
When the ignition is from “high” to “low”, VTC will turn off automatically.
When the ignition is “low”, pressing the power button will not turn on VTC.
Green is for power on/off status.
Orange is for storage status.
Line-out.
Line-out is a stereo output for connecting external speakers.
Mic-in.
Mic-in receives monophonic input from an external microphone.
The external antenna mounting holes are used to mount and connect the antenna to a WLAN module, WWAN
module and GPS.
The LAN port is an RJ45 interface with integrated LEDs and supports 10/100/1000Mbps Ethernet data transfer
rates.
DB9 female connector for 3 GPIO Input (source type; 0~30V ), Output (sink type;20mA max) and CAN bus
support.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
4
VTC 100 User Manual
Page 18
Chapter 1: Product Introduction
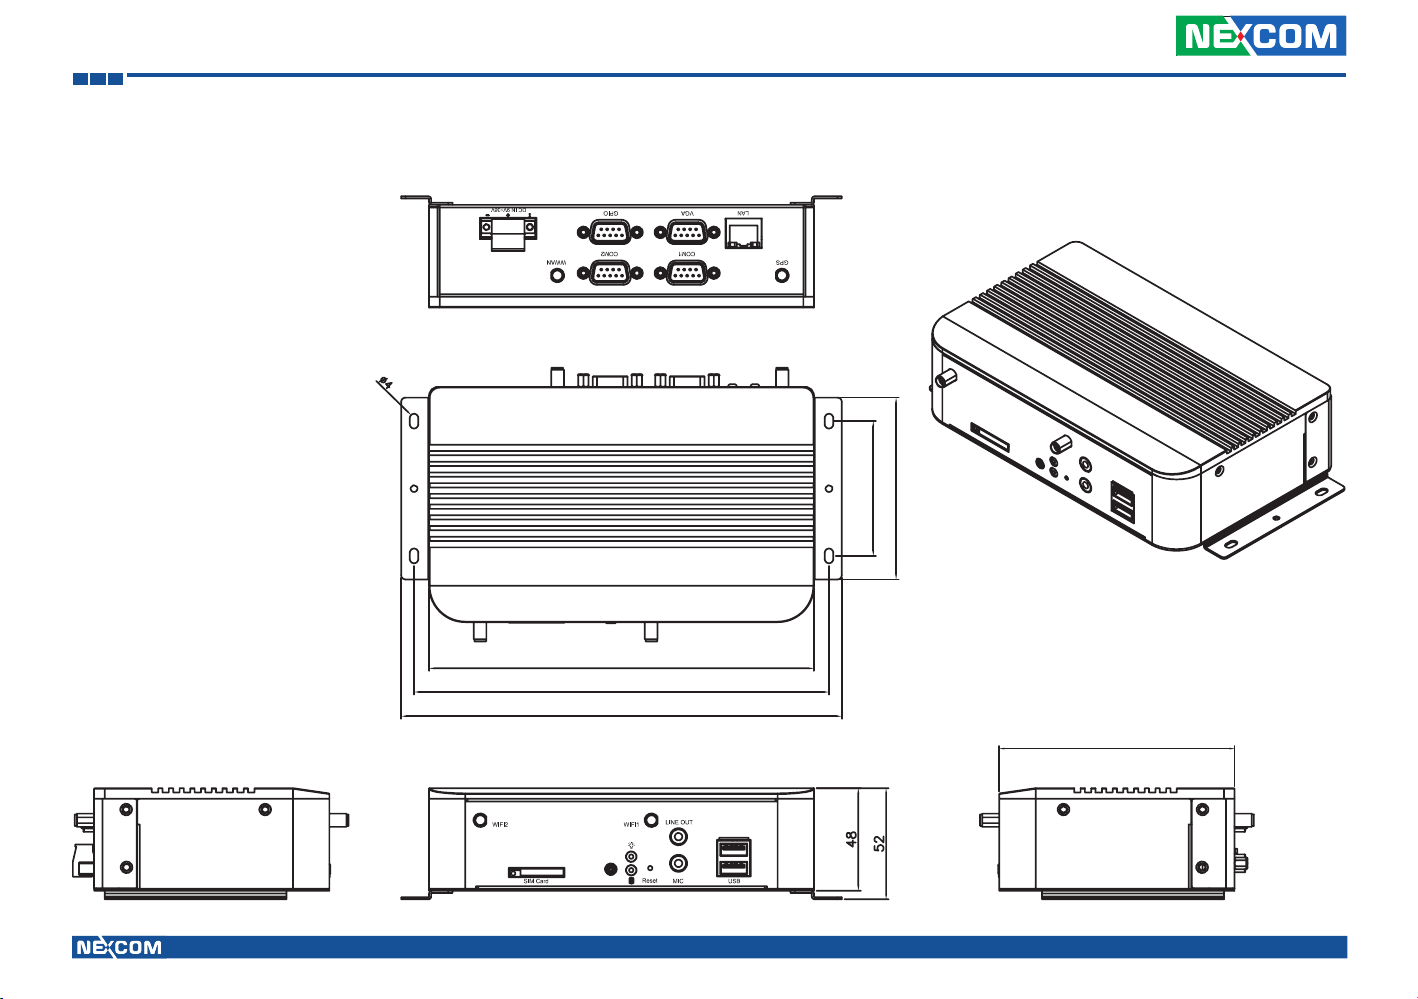
Mechanical Dimensions
63
85
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
180
194
206
110
5
VTC 100 User Manual
Page 19
Chapter 2: Jumpers and Connectors
Chapter 2: Jumpers and Connectors
This chapter describes how to set the jumpers on the motherboard. Note
that the following procedures are generic for all VTC 100 series.
Before You Begin
• Ensure you have a stable, clean working environment. Dust and dirt can
get into components and cause a malfunction. Use containers to keep
small components separated.
• Adequate lighting and proper tools can prevent you from accidentally
damaging the internal components. Most of the procedures that follow
require only a few simple tools, including the following:
• A Philips screwdriver
• A flat-tipped screwdriver
• A set of jewelers Screwdrivers
• A grounding strap
• An anti-static pad
• Using your fingers can disconnect most of the connections. It is recom-
mended that you do not use needle-nosed pliers to disconnect connections as these can damage the soft metal or plastic parts of the connectors.
• Before working on internal components, make sure that the power is off.
Ground yourself before touching any internal components, by touching
a metal object. Static electricity can damage many of the electronic com-
ponents. Humid environment tend to have less static electricity than dry
environments. A grounding strap is warranted whenever danger of static
electricity exists.
Precautions
Computer components and electronic circuit boards can be damaged by
discharges of static electricity. Working on the computers that are still connected to a power supply can be extremely dangerous.
Follow the guidelines below to avoid damage to your computer or yourself:
• Always disconnect the unit from the power outlet whenever you are
working inside the case.
• If possible, wear a grounded wrist strap when you are working inside the
computer case. Alternatively, discharge any static electricity by touching
the bare metal chassis of the unit case, or the bare metal body of any
other grounded appliance.
• Hold electronic circuit boards by the edges only. Do not touch the com-
ponents on the board unless it is necessary to do so. Don’t flex or stress
the circuit board.
• Leave all components inside the static-proof packaging that they shipped
with until they are ready for installation.
• Use correct screws and do not over tighten screws.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
6
VTC 100 User Manual
Page 20
Chapter 2: Jumpers and Connectors
Jumper
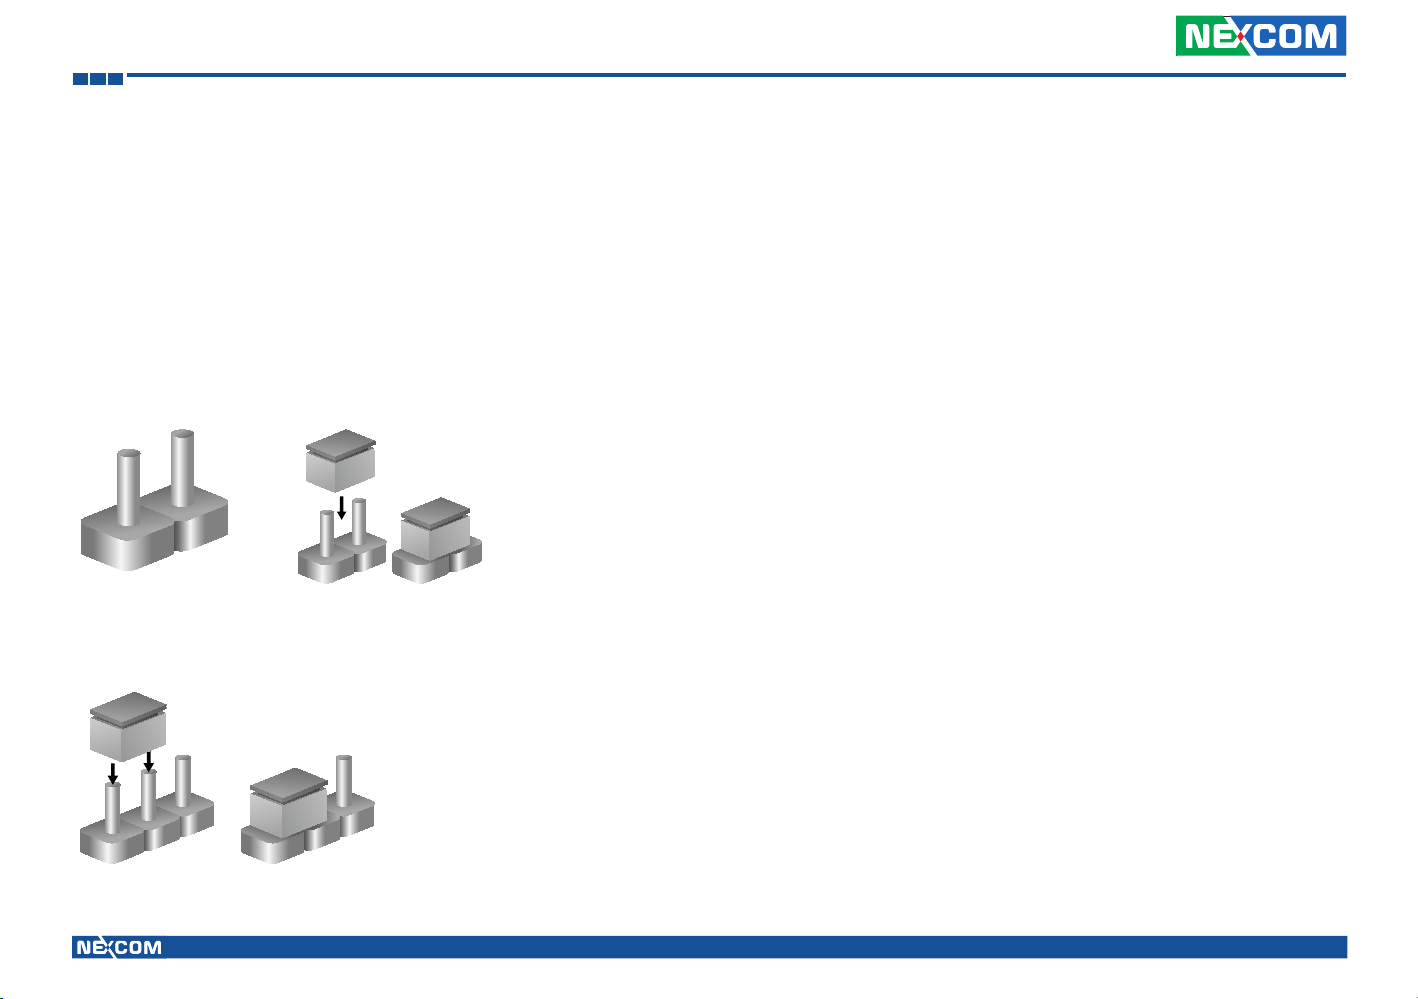
A jumper is the simplest kind of electric switch. It consists of two metal
pins and a cap. When setting the jumpers, ensure that the jumper caps are
placed on the correct pins. When the jumper cap is placed on both pins, the
jumper is short. If you remove the jumper cap, or place the jumper cap on
just one pin, the jumper is open.
Refer to the illustrations below for examples of what the 2-pin and 3-pin
jumpers look like when they are short (on) and open (off).
Two-Pin Jumpers: Open (Left) and Short (Right)
Three-Pin Jumpers: Pins 1 and 2 Are Short
3
2
1
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
1
3
2
7
VTC 100 User Manual
Page 21
Chapter 2: Jumpers and Connectors
JP2 J2
JP1
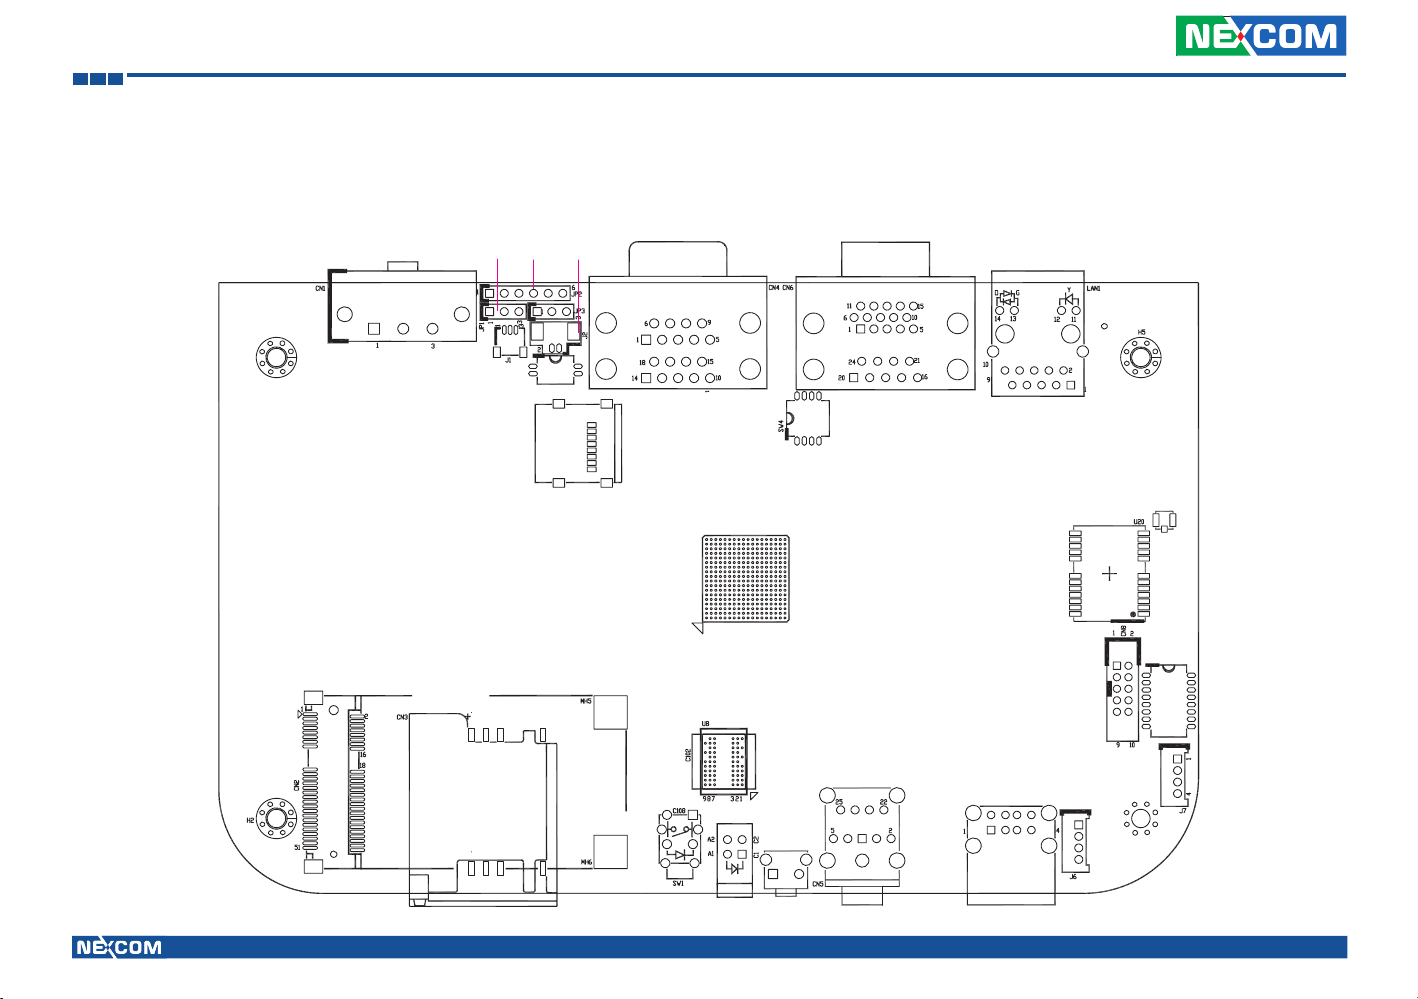
Locations of the Jumpers and Connectors
The figure below is the main board which is the board used in the VTC 100 system. It shows the locations of the jumpers and connectors.
CN4 CN6 LAN1
CN1
J1
SW5
CN2
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
CN3
J3
SW1
LED1
8
SW2
SW4
CN5
CN9
SW3
CN8
J7
J6
VTC 100 User Manual
Page 22
Chapter 2: Jumpers and Connectors
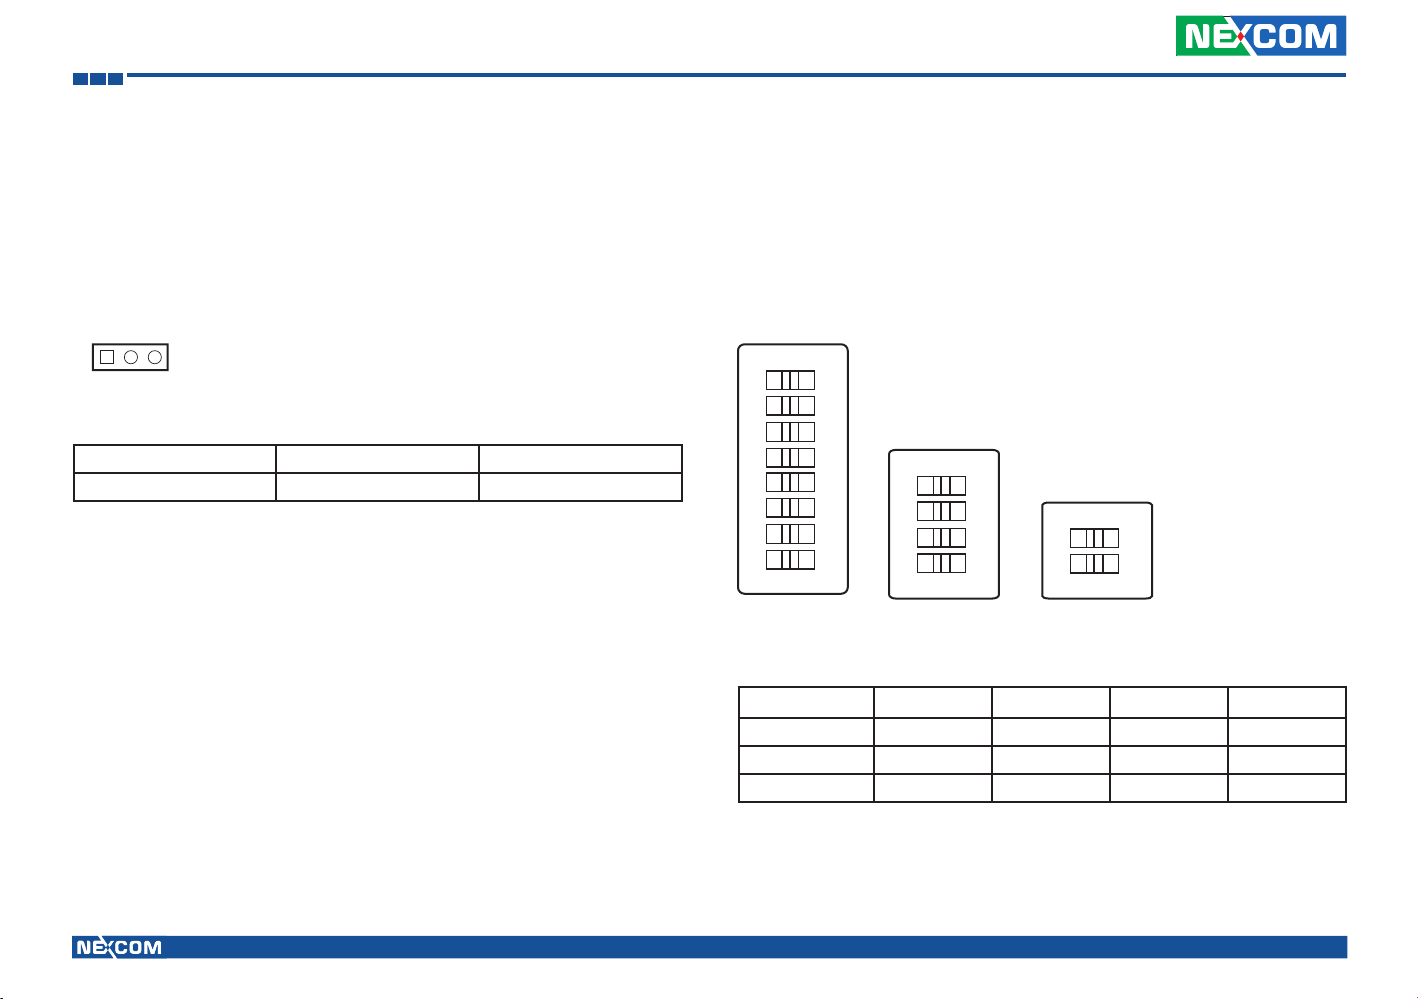
Jumper and DIP Switch Settings
MCU Bootloader Power Select
Connector type: 1x3 3-pin header, 2.54mm pitch
Connector location: JP1
1 3
Pin Status Function Description
1-2 Short +3.3V
DIP Switch
Connector location: SW3, SW4, SW5
SW3
1
2
3
O
N
SW4
4
5
6
7
8 9
SW3 Connector pin definition
SW3
Delay ON/OFF Full Off Full Open
Pin1(Delay OFF) OFF ON OFF ON
Pin2(Delay ON) OFF OFF ON ON
1
2
3
4 5
O
N
SW5
O
1
N
2 3
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
9
VTC 100 User Manual
Page 23
Chapter 2: Jumpers and Connectors
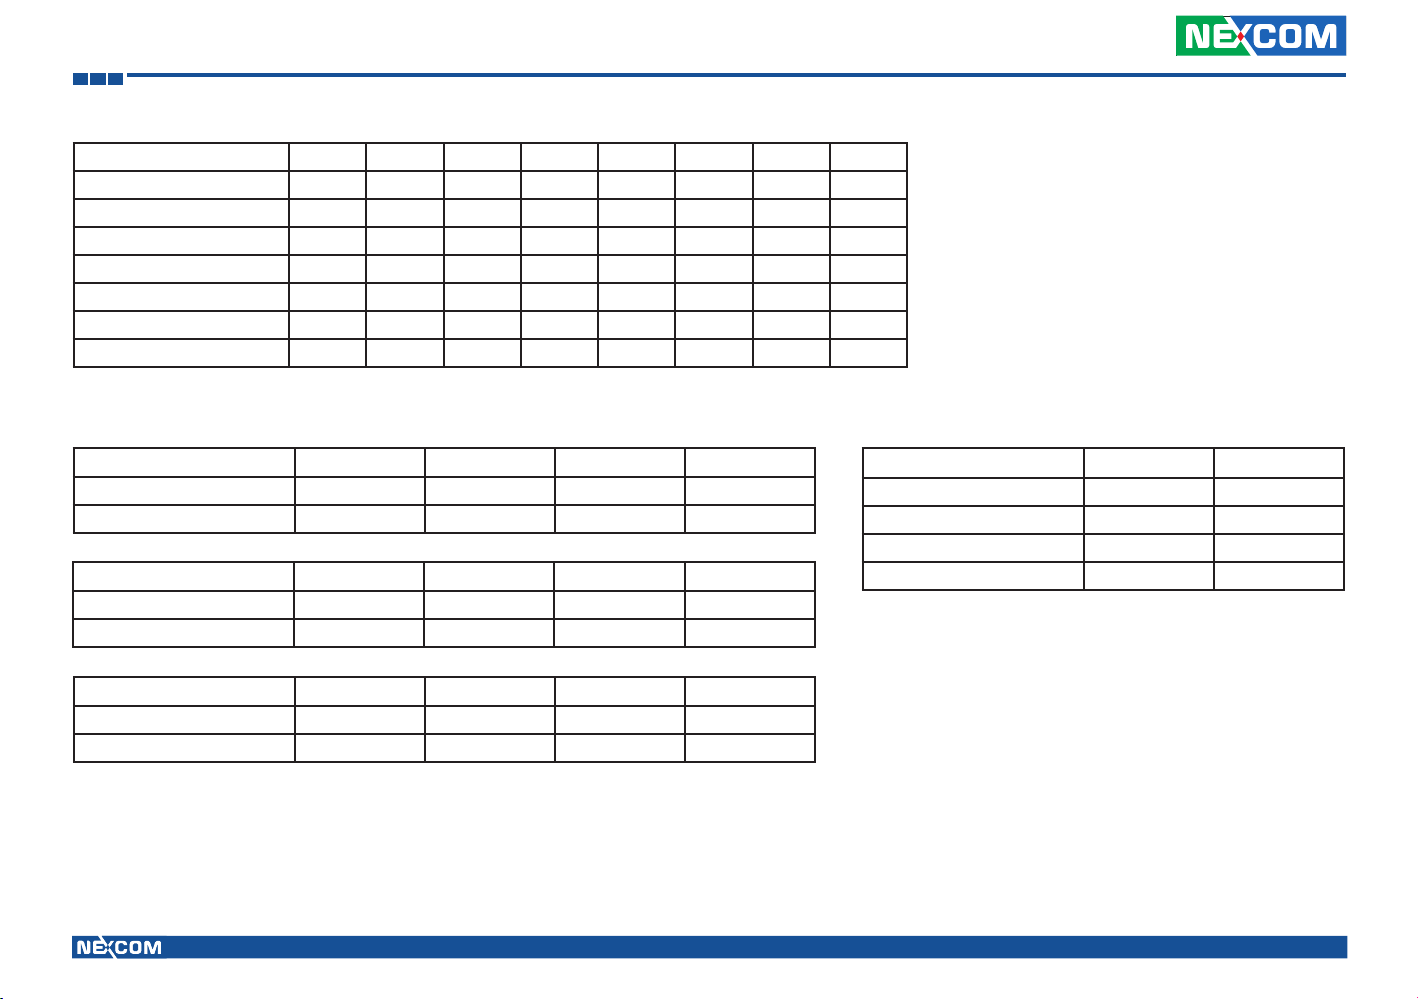
Time Setting (Delay ON) 10Sec 30Sec 1Min 5Min 10Min 15Min 30Min 1Hour
Pin3 OFF OFF OFF OFF ON ON ON ON
Pin4 OFF OFF ON ON OFF OFF ON ON
Pin5 OFF ON OFF ON OFF ON OFF ON
Time Setting (Delay OFF) 20Sec 1Min 5Min 10Min 30Min 1Hour 6Hour 18Hour
Pin6 OFF OFF OFF OFF ON ON ON ON
Pin7 OFF OFF ON ON OFF OFF ON ON
Pin8 OFF ON OFF ON OFF ON OFF ON
SW4 Connector pin definition SW5 Connector pin definition
Startup/Shutdown
11.5V/10.5V 12V/11V 12.5V/11V 12.5V/11.5V
Pin1 OFF ON OFF ON
Pin2 OFF OFF ON ON
SW5
ON/OFF MCU BOOT MCU NOMO
Pin1 (MCU BOOT) ON OFF
ON/OFF 800X600 640X480
Startup/Shutdown
23V/21V 24V/22V 25V/22V 25V/23V
Pin2 (VGA RES SET) OFF ON
Pin1 OFF ON OFF ON
Pin2 OFF OFF ON ON
Setting Voltage 12V/24V
12V 24V 9~36V 9~36V
Pin3 ON ON OFF OFF
Pin4 ON OFF ON OFF
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
10
VTC 100 User Manual
Page 24
Chapter 2: Jumpers and Connectors
16
3
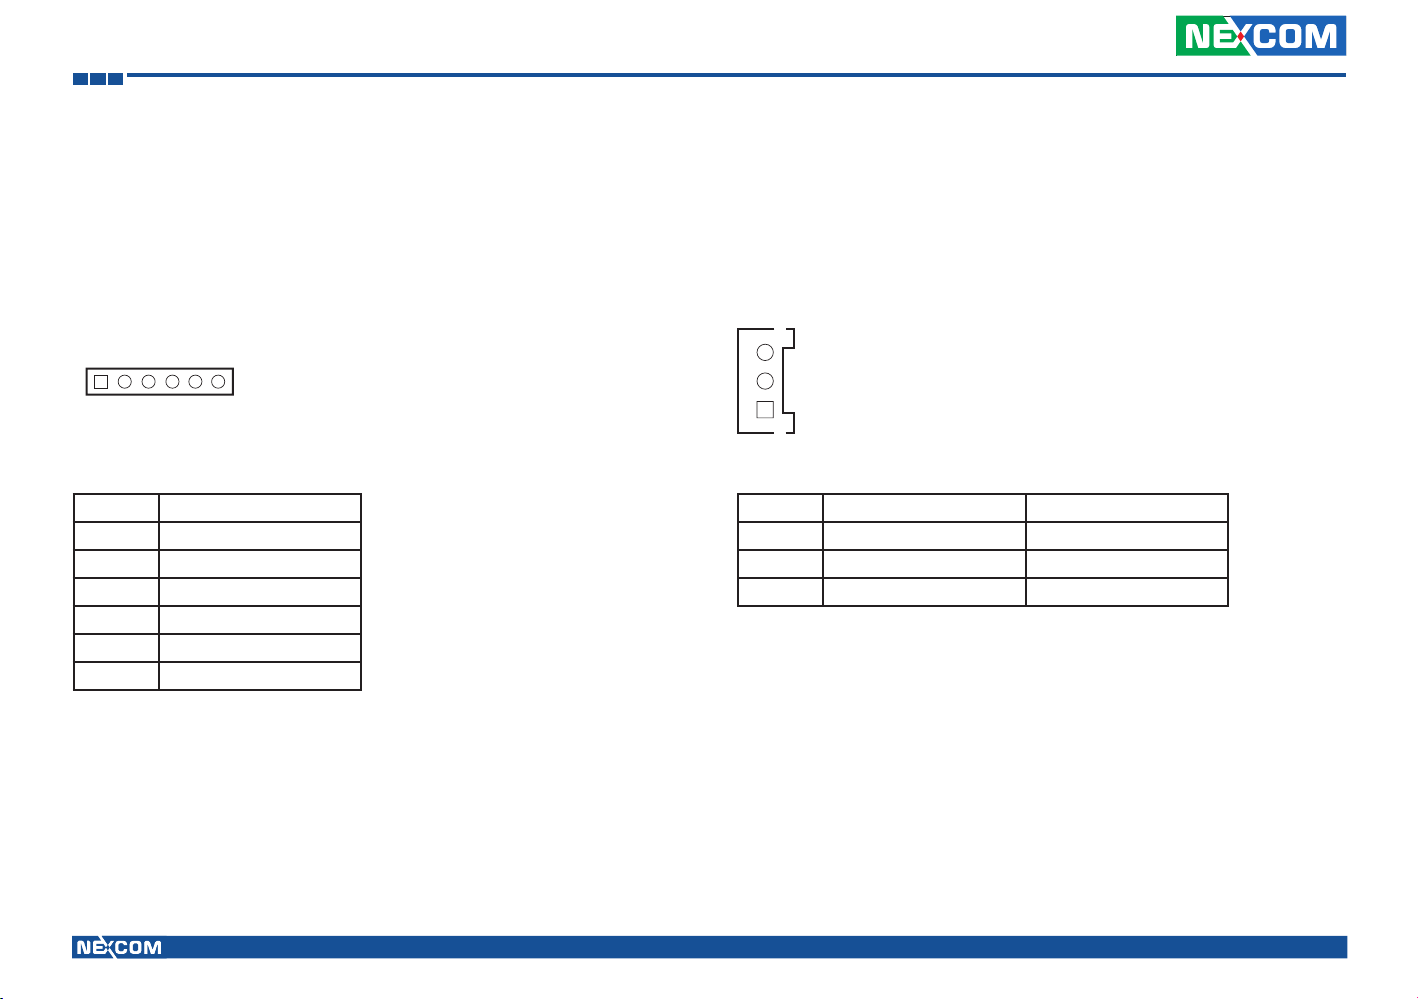
Connectors
MCU Bootloader Pin Definition
Connector type: 1x6 6-pin header, 2.54mm pitch
Connector location: JP2
Pin Defintion
1 +3.3V
2 SWDIO
3 SWDCLK
4 SWO
5 nRESET
6 GND
Debug Ports
Connector type: 1x3 3-pin header, 1.0mm pitch
Connector location: J1 (MCU) and J5 (SOC)
1
Pin Pin Name (J1) Pin Name (J5)
1 GND GND
2 MCU RXD MPU RXD_0
3 MCU TXD MPU TXD_0
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
11
VTC 100 User Manual
Page 25
Chapter 2: Jumpers and Connectors
2
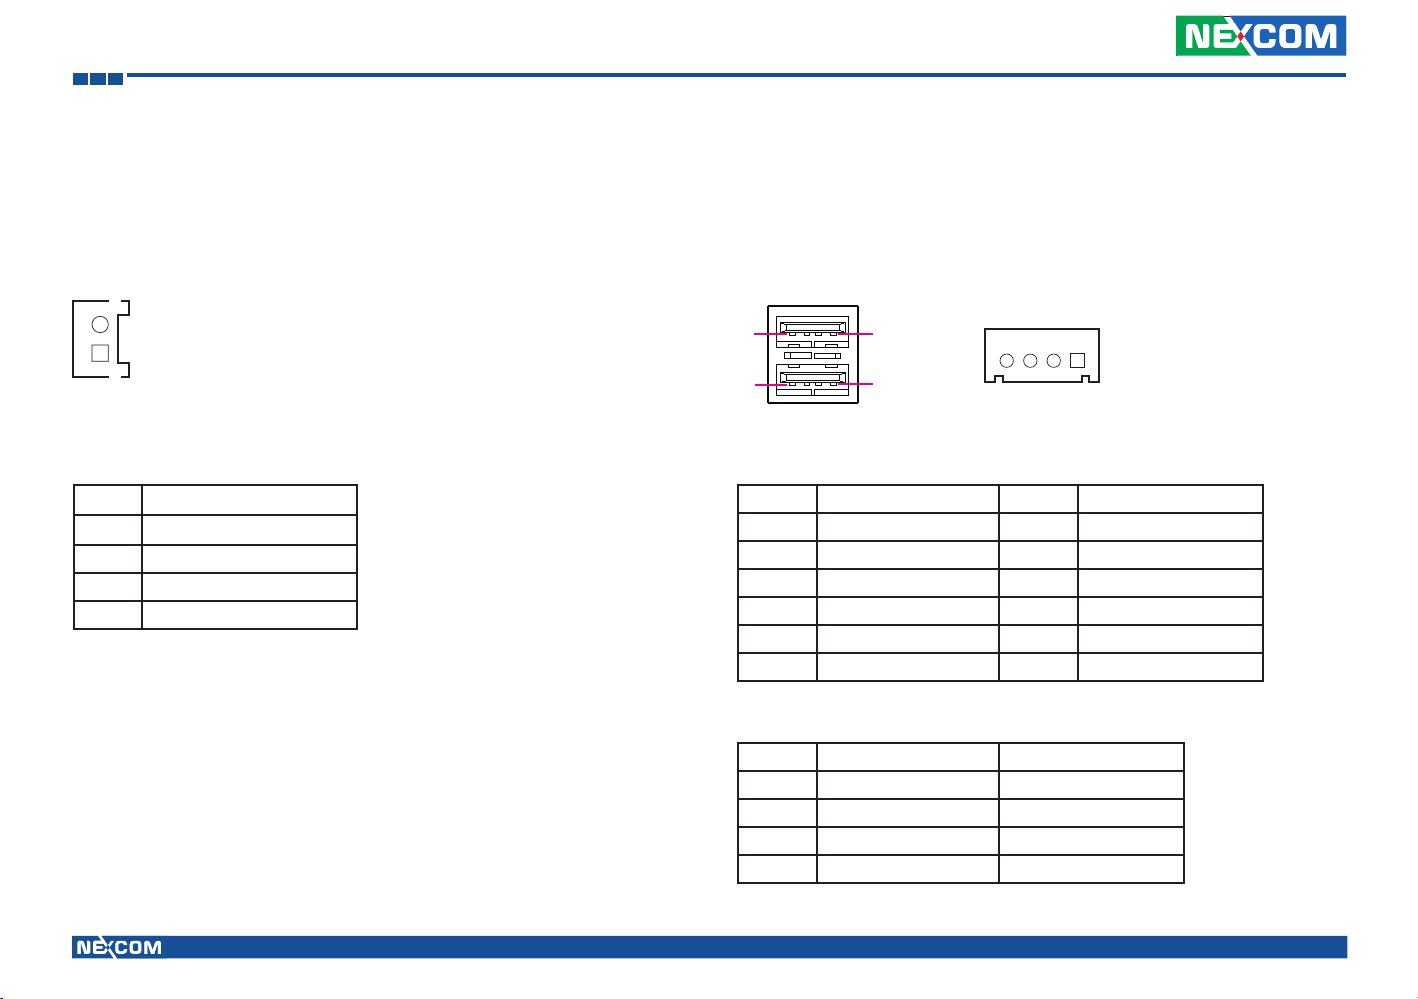
VBAT CONN
Connector type: 1x2 2-pin header, 1.25mm pitch
Connector location: J2
1
Connector pin definition
PIn Definition
1 GND
2 +3V
MH1 GND
MH2 GND
USB Ports
Connector type: Dual USB ports
1x4 4-pin header, 1.25mm pitch
Connector location: CN7 (External), J6 and J7 (Internal)
1
5
CN7
CN7 Connector pin definition
Pin Definition Pin Definition
1 Power(+5V) 2 D-
3 D+ 4 GND
5 POWER(+5V) 6 D-
7 D+ 8 GND
MH1 GND MH2 GND
MH3 GND MH4 GND
J6 & J7 Connector pin definition
Pin Name (J6 USB Client) Name (J7 USB HOST)
1 VBUS POWER(+5V)
2 D- D-
3 D+ D+
4 GND GND
4
14
8
J6 & J7
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
12
VTC 100 User Manual
Page 26
Chapter 2: Jumpers and Connectors
1
3
2
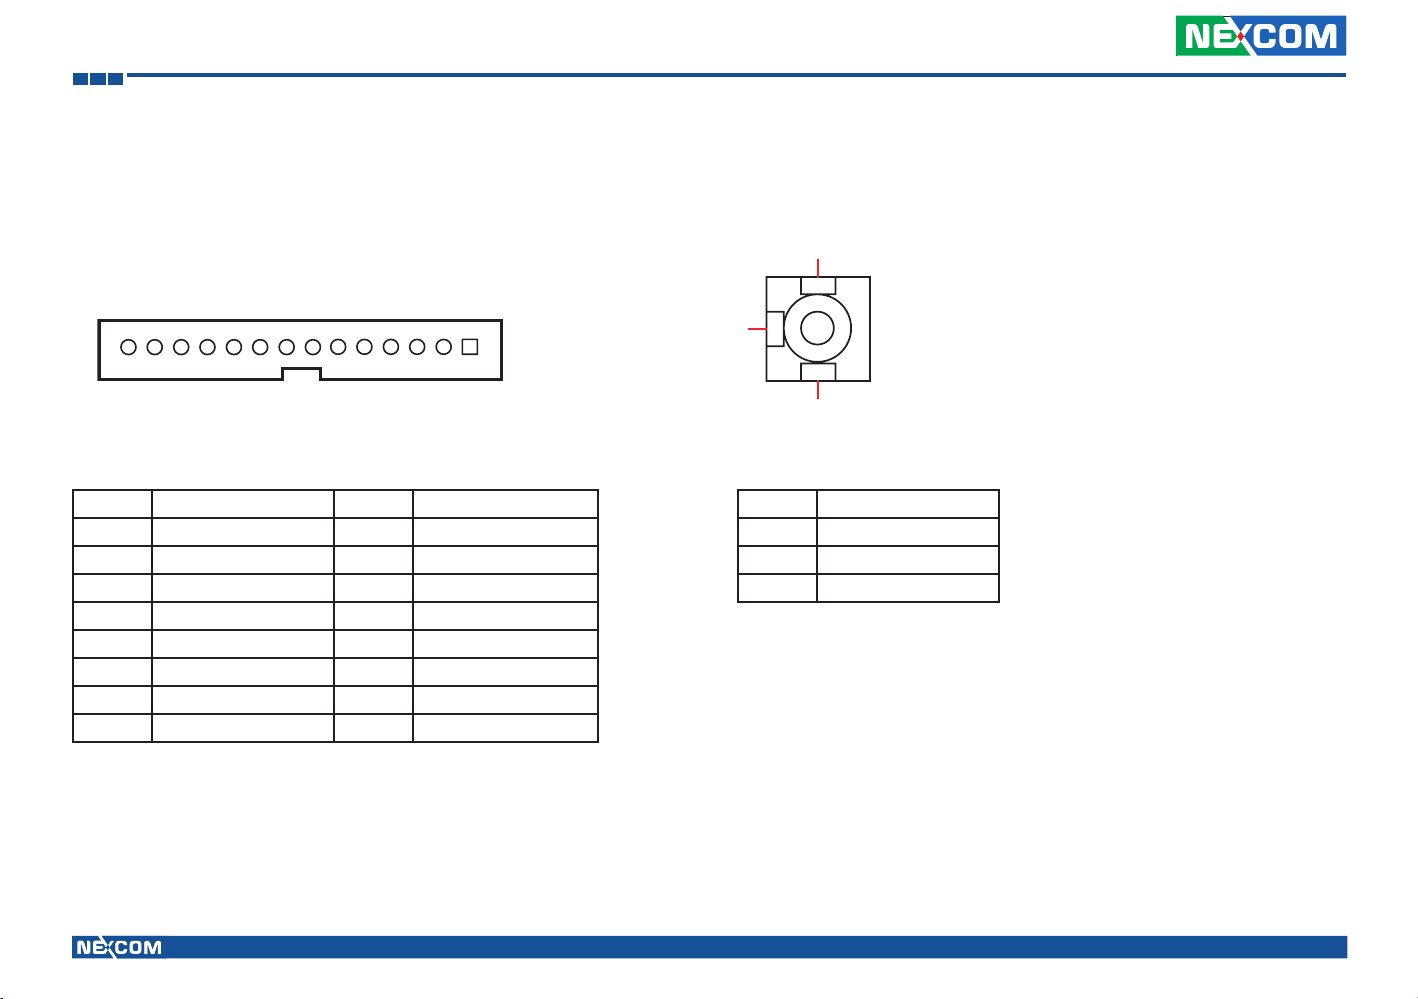
WIFI & BT Connector
Connector type: 1x16 16-pin header, 1.0mm pitch
GPS Connector
Connector location: CN9
Connector location: J4
116
Connector pin definition Connector pin definition
Pin Definition Pin Definition
1 N/A 2 N/A
3 GND 4 WLAN_EN
5 WLAN_RESET 6 GND
7 WIFI CLK 8 WIFI CMD
9 WIFI DAT3 10 WIFI DAT2
11 WIFI DAT1 12 WIFI DAT0
13 GND 14 GND
15 POWER(+3.3V) 16 POWER(+3.3V)
Pin Definition
1 RF IN
2 GND
3 GND
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
13
VTC 100 User Manual
Page 27
Chapter 2: Jumpers and Connectors
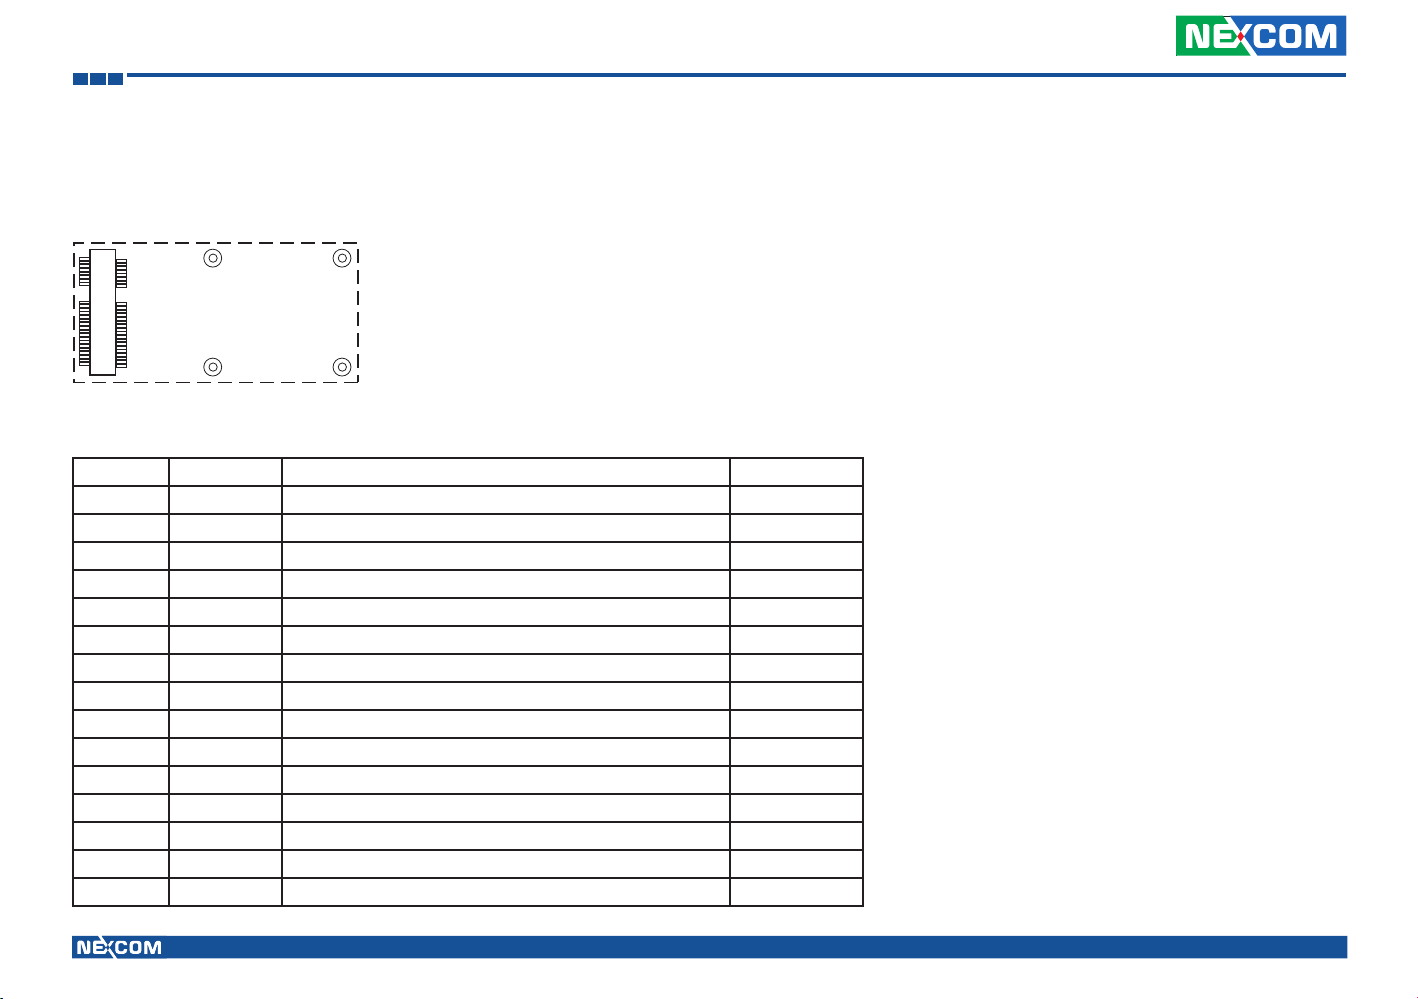
Mini PCI-E Connector
Connector location: CN2
2
51152
Important Pin Assignments
Pin In/Output Function Voltage Levels
1,3 IN Microphone
5,7 OUT Speaker Out
11 OUT GSM Module VREF OUT 1.8V or 2.6V
17 OUT PCM Data Out
19 OUT PCM Sync Out
32 OUT SMS RI Out, for wake up system
33 IN RESET#
45 OUT PCM CLK Out
47 IN PCM Data In
49 OUT UART Receive Data (GSM Module need to connect to TX)
51 IN UART Transmit Data (GSM Module need to connect to RX)
36,38 IN/OUT USB
20 IN Module Disable (Low)
42 OUT WWAN LED
8,10,12,14 IN/OUT SIM Card
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
14
VTC 100 User Manual
Page 28
Chapter 2: Jumpers and Connectors
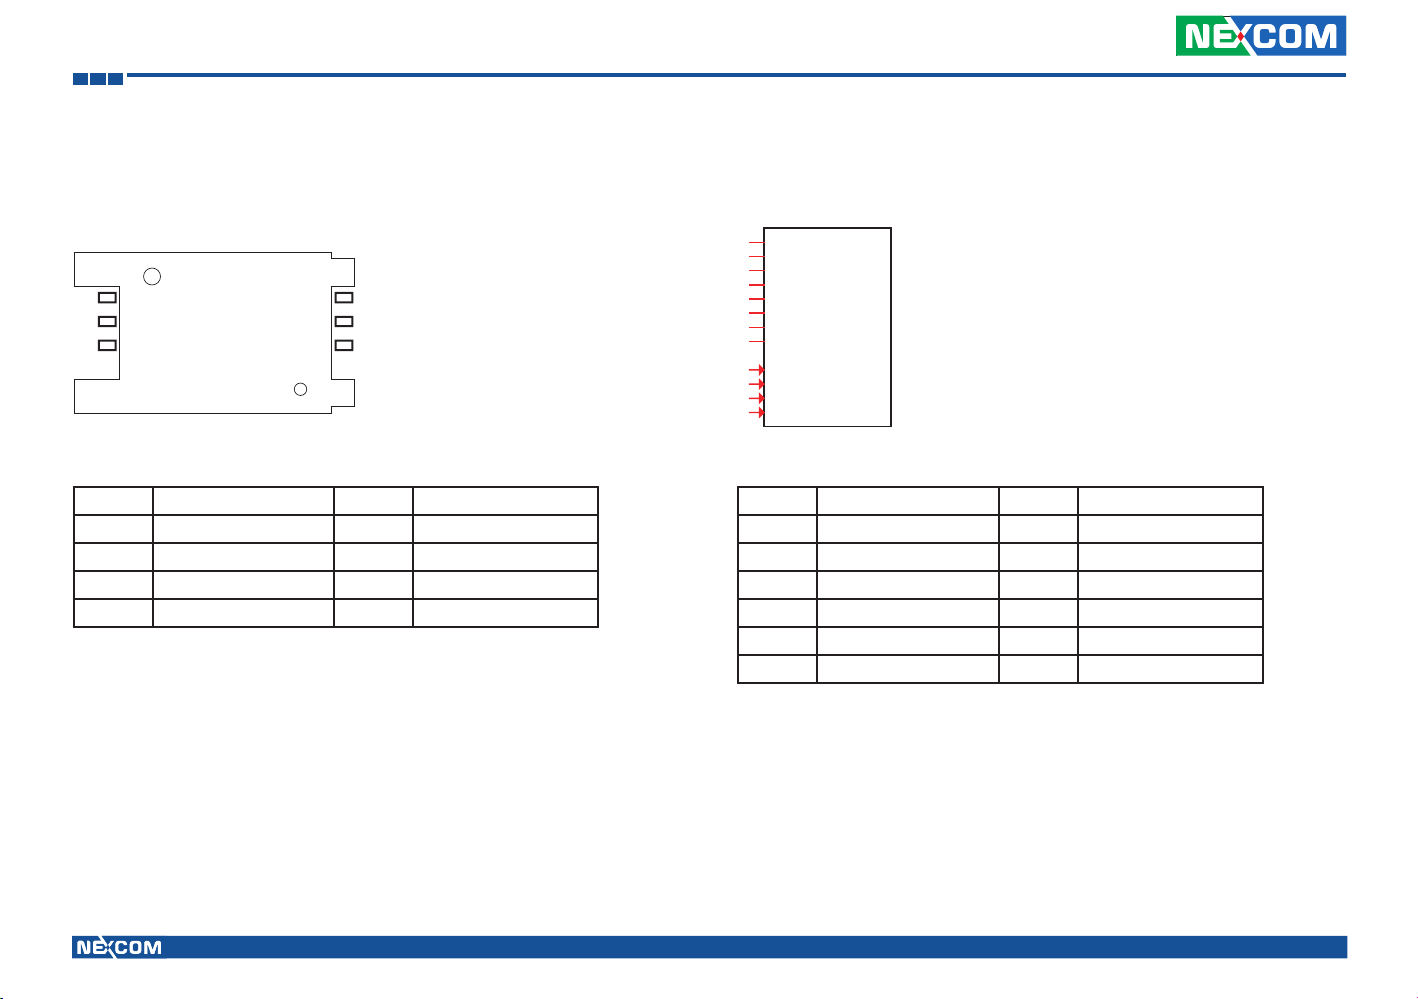
SIM Card Connector
Connector location: CN3
C3
C2
C1
C7
C6
C5
Micro SD Connector
Connector location: J3
1
DAT2
2
CD/DAT3
3
CMD
4
VDD
5
CLK
6
VSS
7
DAT0
8
DAT1
H1
GND1
H2
GND2
H3
GND3
H4
GND4
Connector pin definition Connector pin definition
Pin Definition Pin Definition
C1 UIM POWER C5 GND
C2 UIM RST C6 NC
C3 UIM CLK C7 UIM DAT
SW1 GND SW2 GND
Pin Definition Pin Definition
1 DAT2 2 DAT3
3 CMD 4 VDD
5 CLK 6 GND
7 DAT0 8 DAT1
MH1 GND MH2 GND
MH3 GND MH4 GND
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
15
VTC 100 User Manual
Page 29
Chapter 2: Jumpers and Connectors
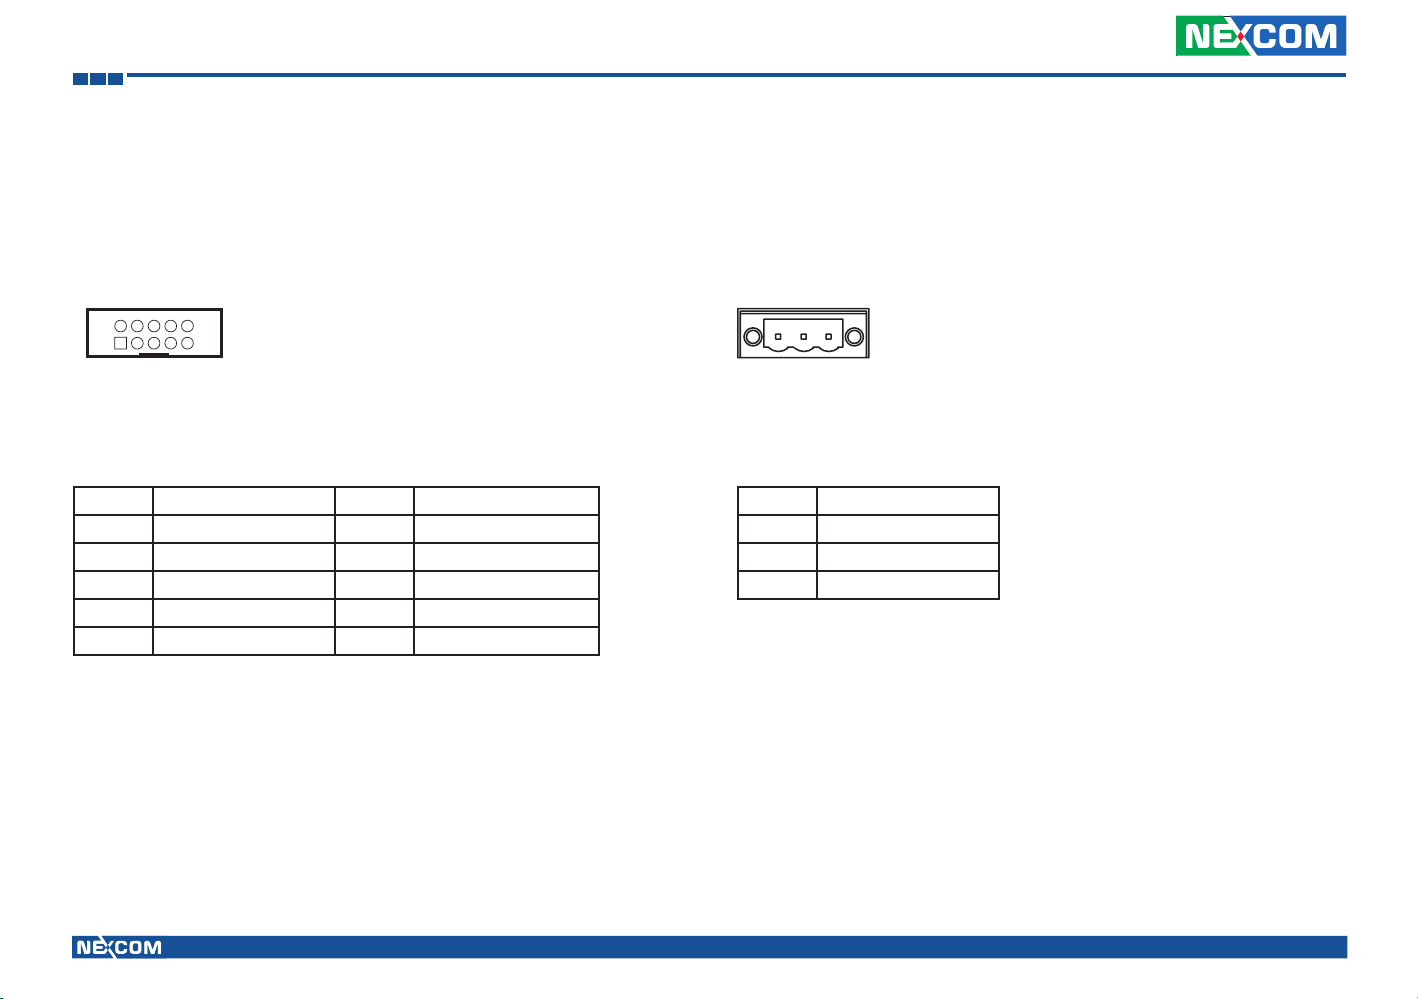
CAN Module Connector
Connector location: CN8
2
1
Connector pin definition Connector pin definition
Pin Definition Pin Definition
1 UR TXD 2 UR RXD
3 CAN DI1 4 CAN DO1
5 GND 6 GND
7 NC 8 NC
9 POWER(+5V) 10 NC
10
9
POWER INPUT (CN1)
Connector location: CN1
13
Pin Definition
1 GND
2 VIN(9V~36V)
3 IGNITION
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
16
VTC 100 User Manual
Page 30
Chapter 2: Jumpers and Connectors
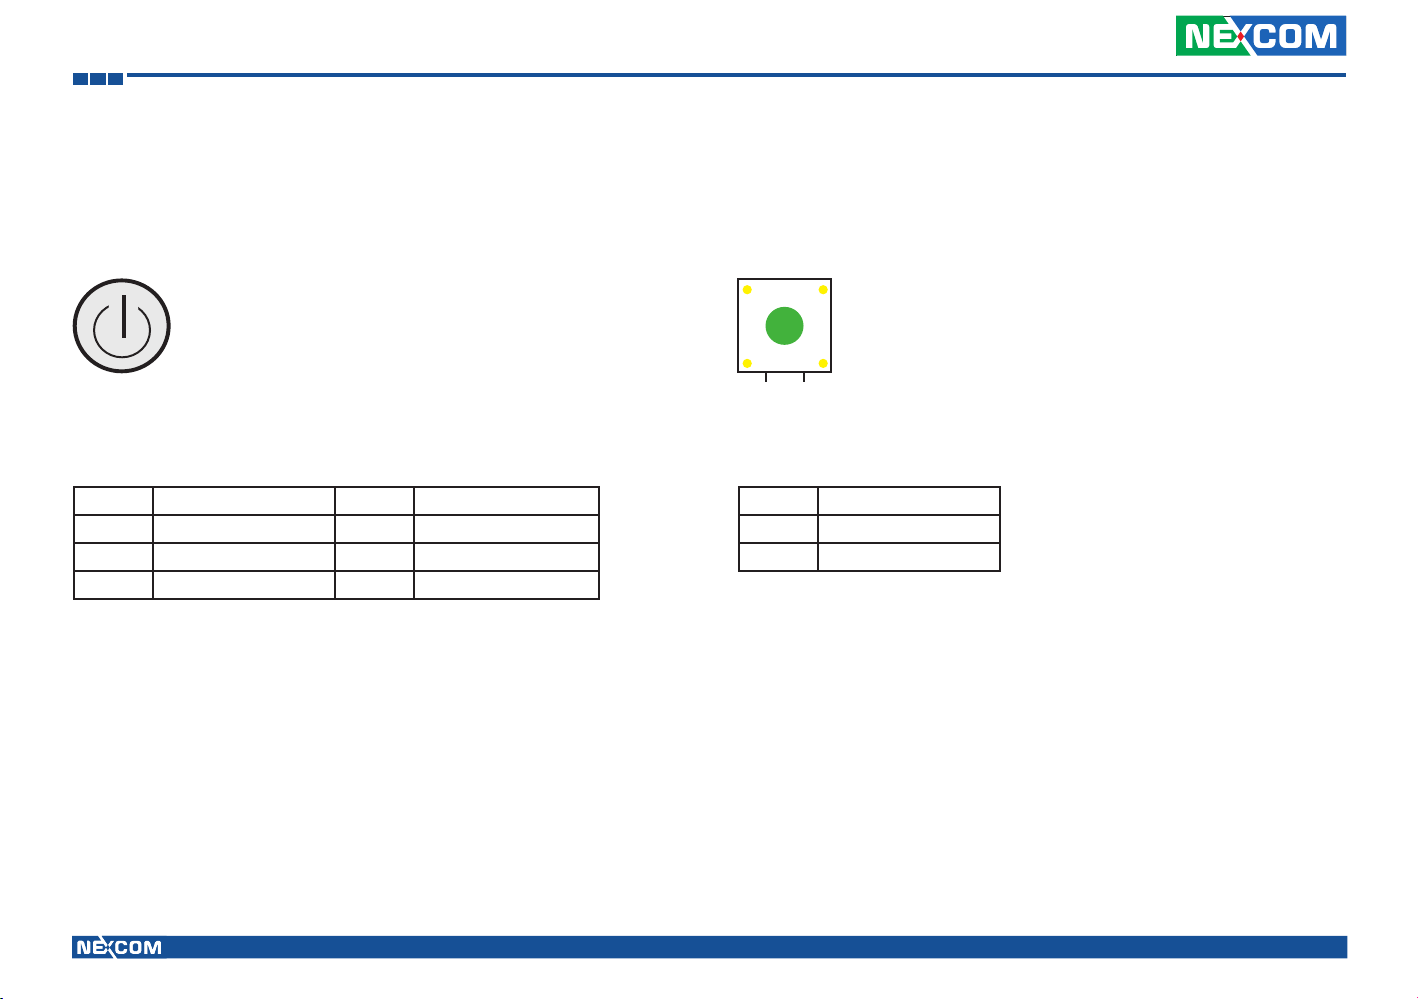
Power Button
Connector location: SW1
Connector pin definition Connector pin definition
Pin Definition Pin Definition
1 GND 2 NC
3 3V3ALW 4 NC
A1 5VSB C1 5VSB
Reset Button
Connector location: SW2
1 3
Pin Definition
1 RST_BTN#
2 GND
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
17
VTC 100 User Manual
Page 31
Chapter 2: Jumpers and Connectors
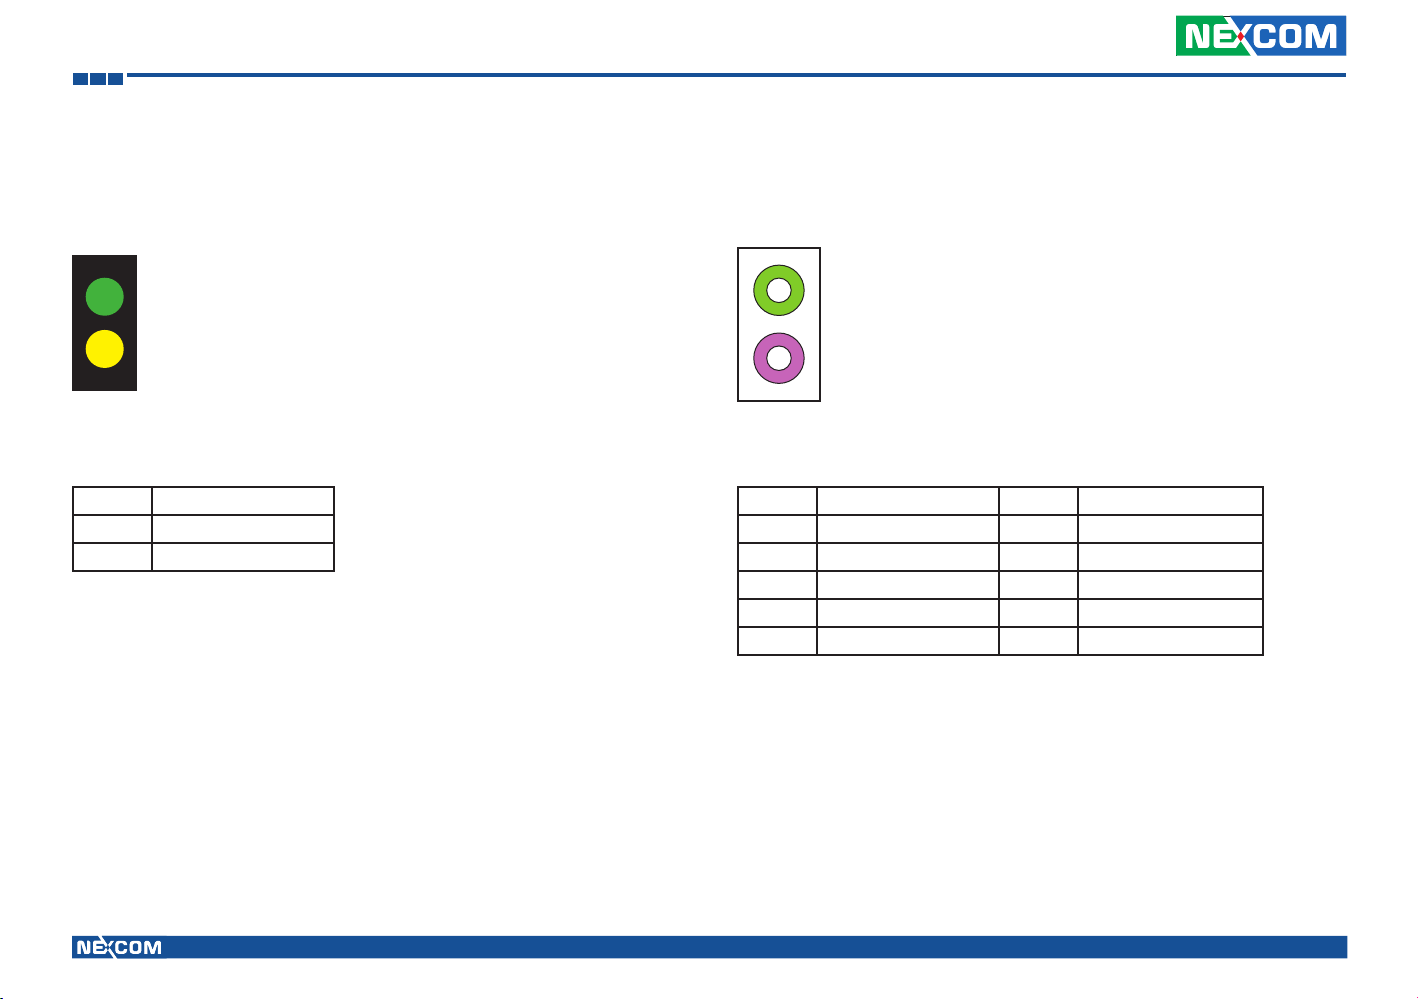
Power On & SD Active LED
Connector location: LED1
T1
B1
LED No. Definition
T1 POWER LED
B1 HD LED
Line-out and Mic-in Connectors
Connector location: CN5B and CN5A
Line-out
Mic-in
Connector pin definitionConnector pin definition
Pin Definition Pin Definition
1 GND 2 NC
3 GND 4 MIC DET
5 MIC JACK 6 NC
22 LINE_OUT_L 23 GND
24 GND 25 LINE_OUT_R
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
18
VTC 100 User Manual
Page 32
Chapter 2: Jumpers and Connectors
Power On & SD Active LED
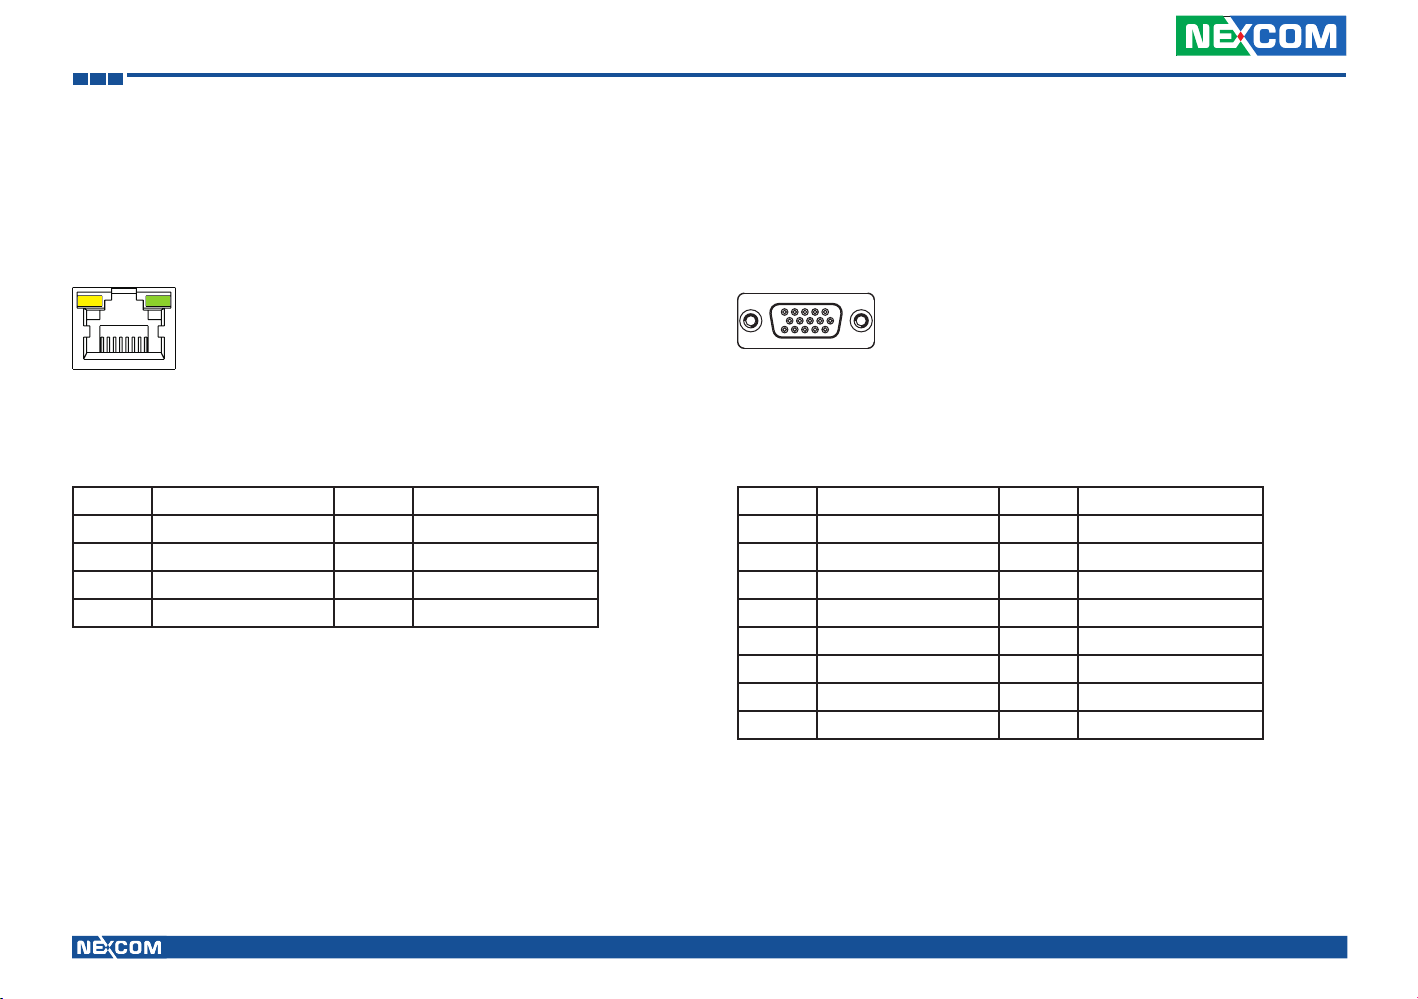
Connector type: RJ-45
Connector location: LAN1
18
Connector pin definition
Pin Definition Pin Definition
1 TX+ 2 TX-
3 RX+ 4 N/C1
5 N/C2 6 RX-
7 N/C3 8 N/C4
VGA connector
Connector type: DB-15 port, 15-pin D-Sub
Connector location: CN6B
1
5
1115
Connector pin definition
Pin Definition Pin Definition
1 RED 2 GREEN
3 BLUE 4 Gnd
5 Gnd 6 Gnd
7 Gnd 8 Gnd
9 VCC 10 Gnd
11 Gnd 12 NC
13 Hsync 14 Vsync
15 NC 16 OPEN
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
19
VTC 100 User Manual
Page 33
Chapter 2: Jumpers and Connectors
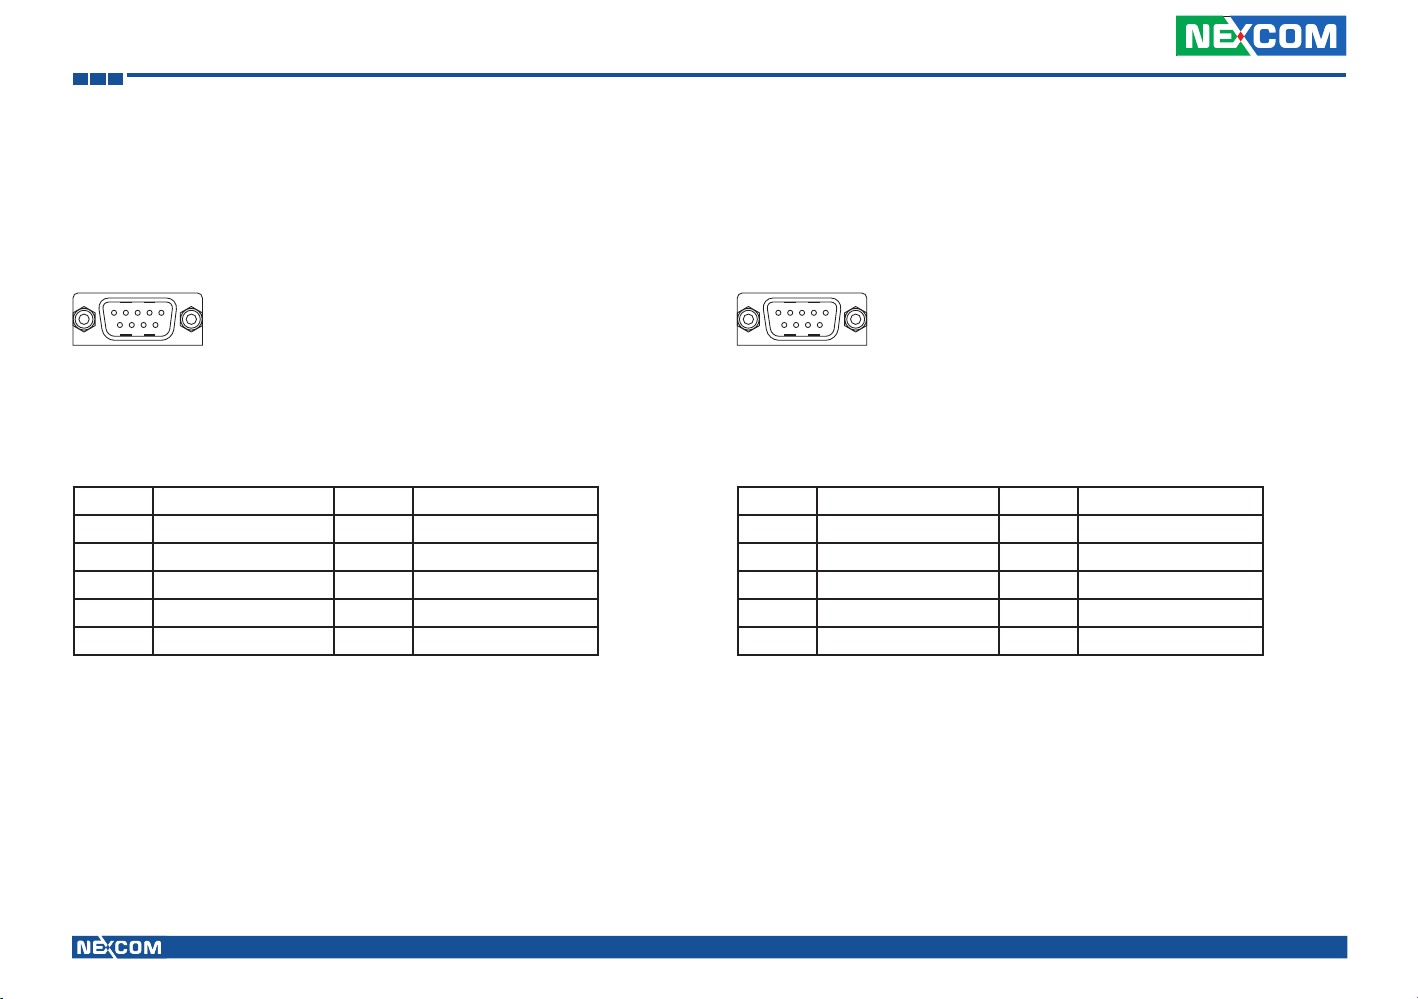
Standard RS232 Interface
Connector type: DB-9 port
Connector location: CN6A
16
20
2421
Connector pin definition
Pin Definition Pin Definition
16 DCD 17 RXD
18 TXD 19 DTR
20 Gnd 21 DSR
22 RTS 23 CTS
24 RI
RS485 connector
Connector type: DB-9 port
Connector location: CN4B
10
14
1815
Connector pin definition
Pin Definition Pin Definition
10 NC 11 NC
12 NC 13 NC
14 GND 15 RS485_-
16 RS485_+ 17 NC
18 NC
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
20
VTC 100 User Manual
Page 34
Chapter 2: Jumpers and Connectors
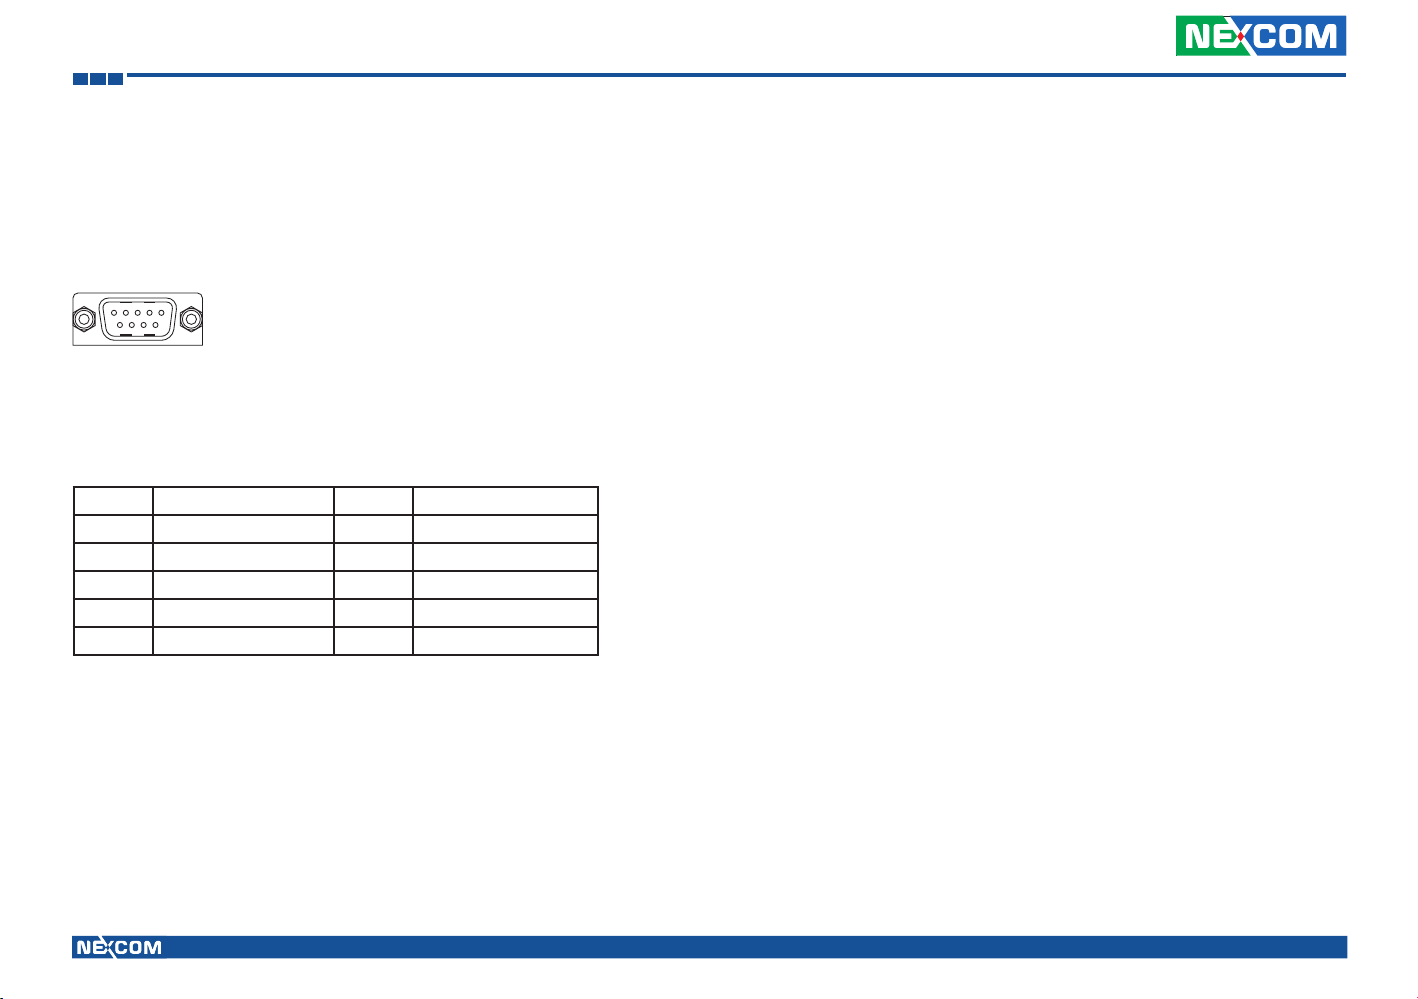
GPIO connector
Connector type: DB-9 port
Connector location: CN4A
5
1
69
Connector pin definition
Pin Definition Pin Definition
1 INPUT_1 PORT 2 INPUT_2 PORT
3 INPUT_3 PORT 4 OUTPUT_1 PORT
5 GND 6 OUTPUT_2 PORT
7 CANH 8 CANL
9 OUTPUT_3 PORT
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
21
VTC 100 User Manual
Page 35
Chapter 3: System Setup
CAUTION!
Chapter 3: System Setup
Removing the Chassis Cover
CAUTION!CAUTION!
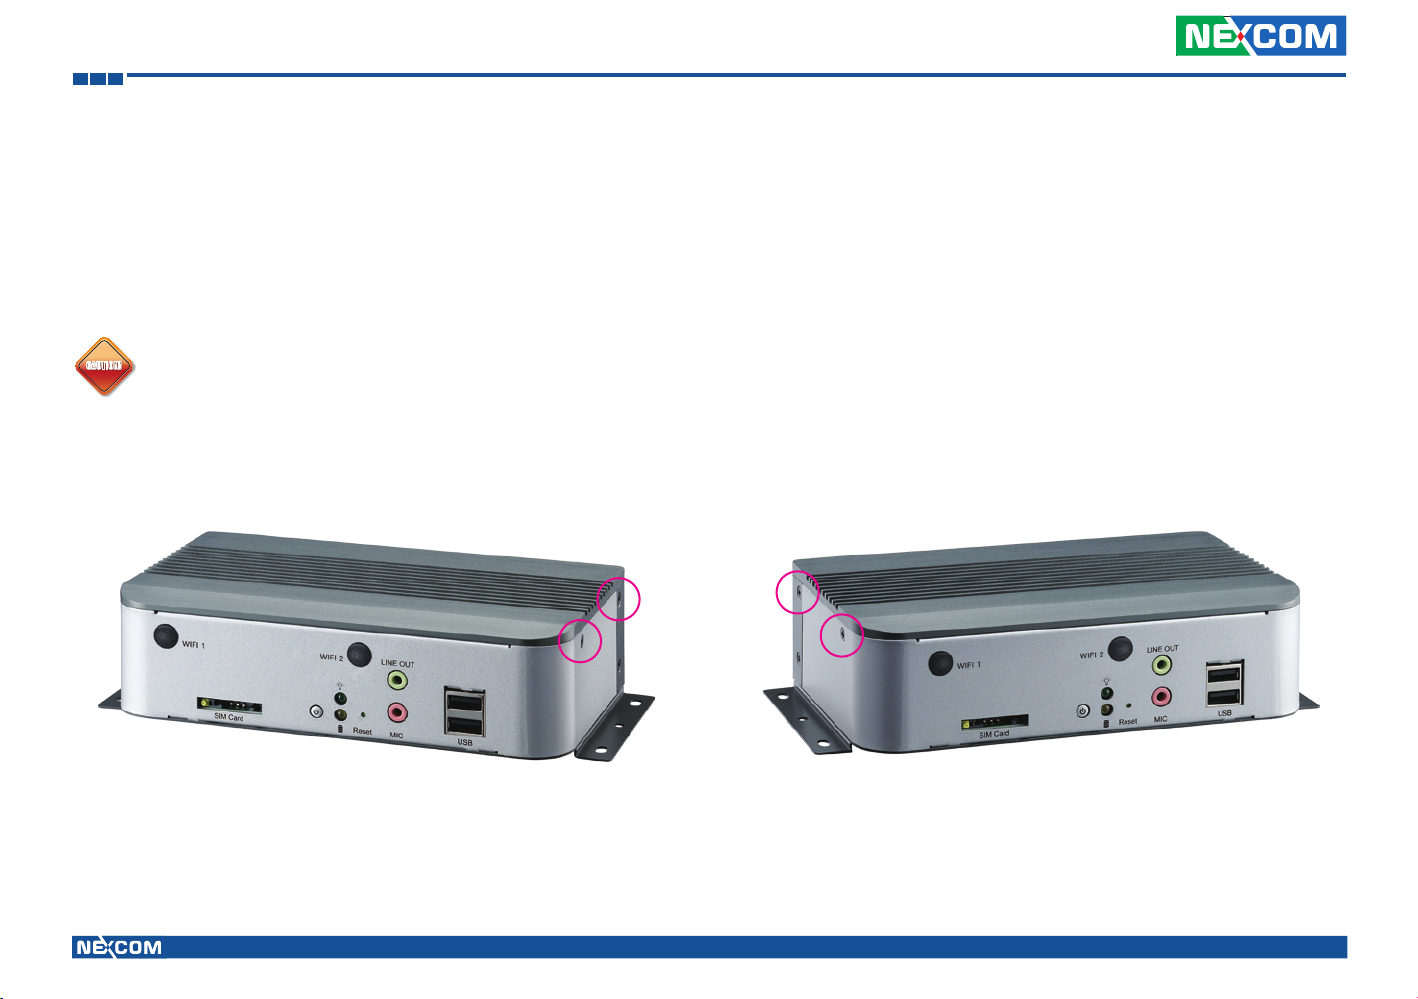
1. The screws on the chassis are used to secure the cover to the chassis.
Prior to removing the chassis cover, make sure the unit’s power is off and disconnected from the power sources to prevent electric
shock or system damage.
Remove these screws and put them in a safe place for later use
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
22
VTC 100 User Manual
Page 36
Chapter 3: System Setup
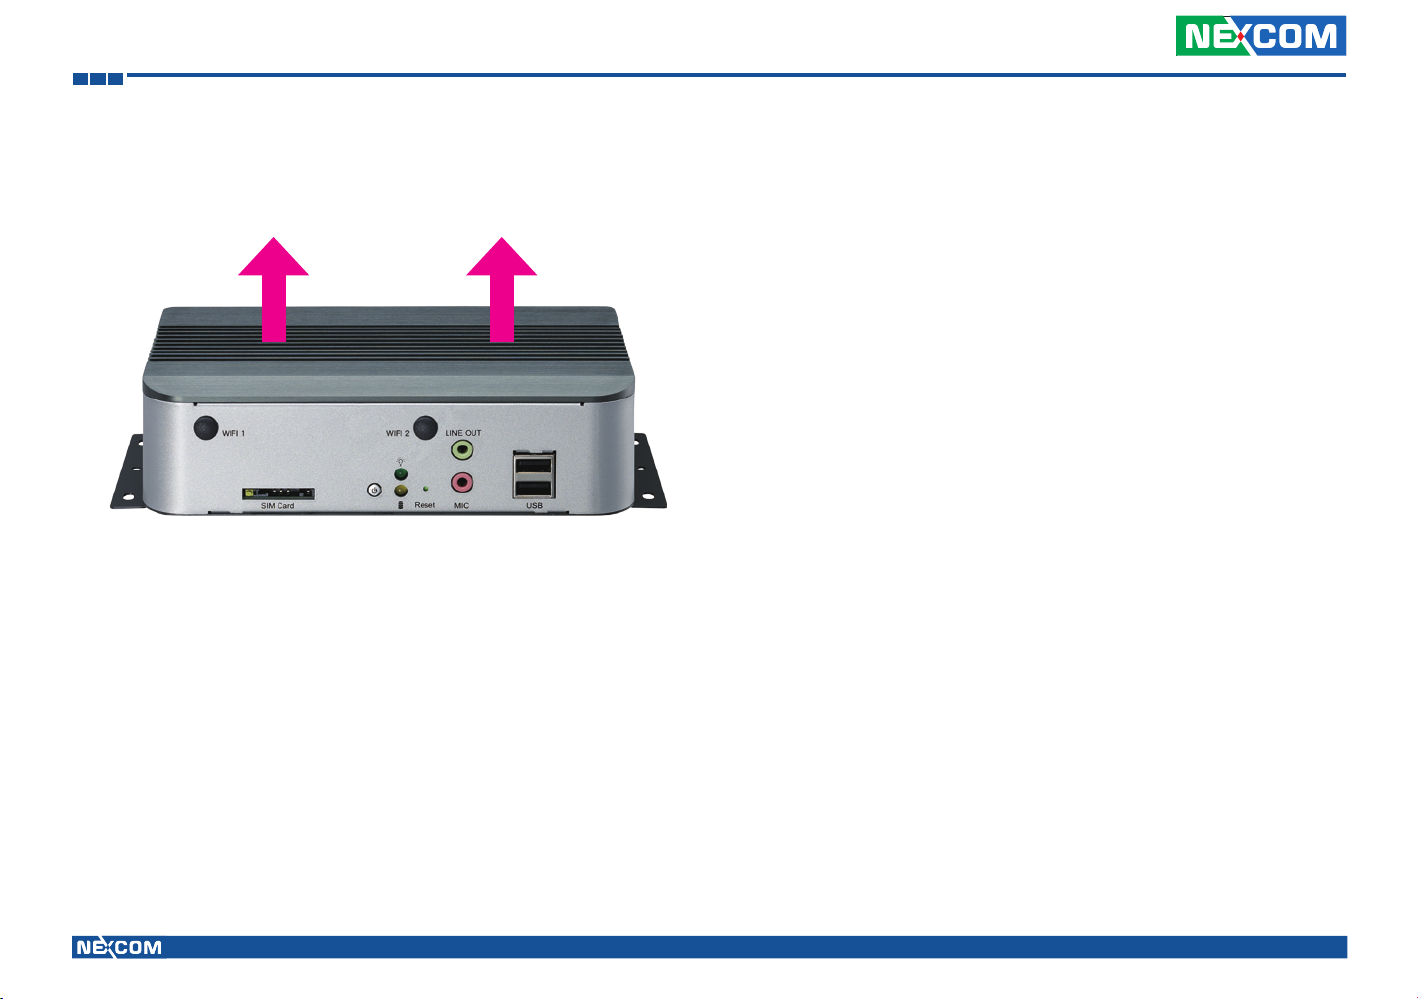
2. Lift the cover upward then remove it from the chassis.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
23
VTC 100 User Manual
Page 37
Chapter 3: System Setup
Installing a WWAN Module
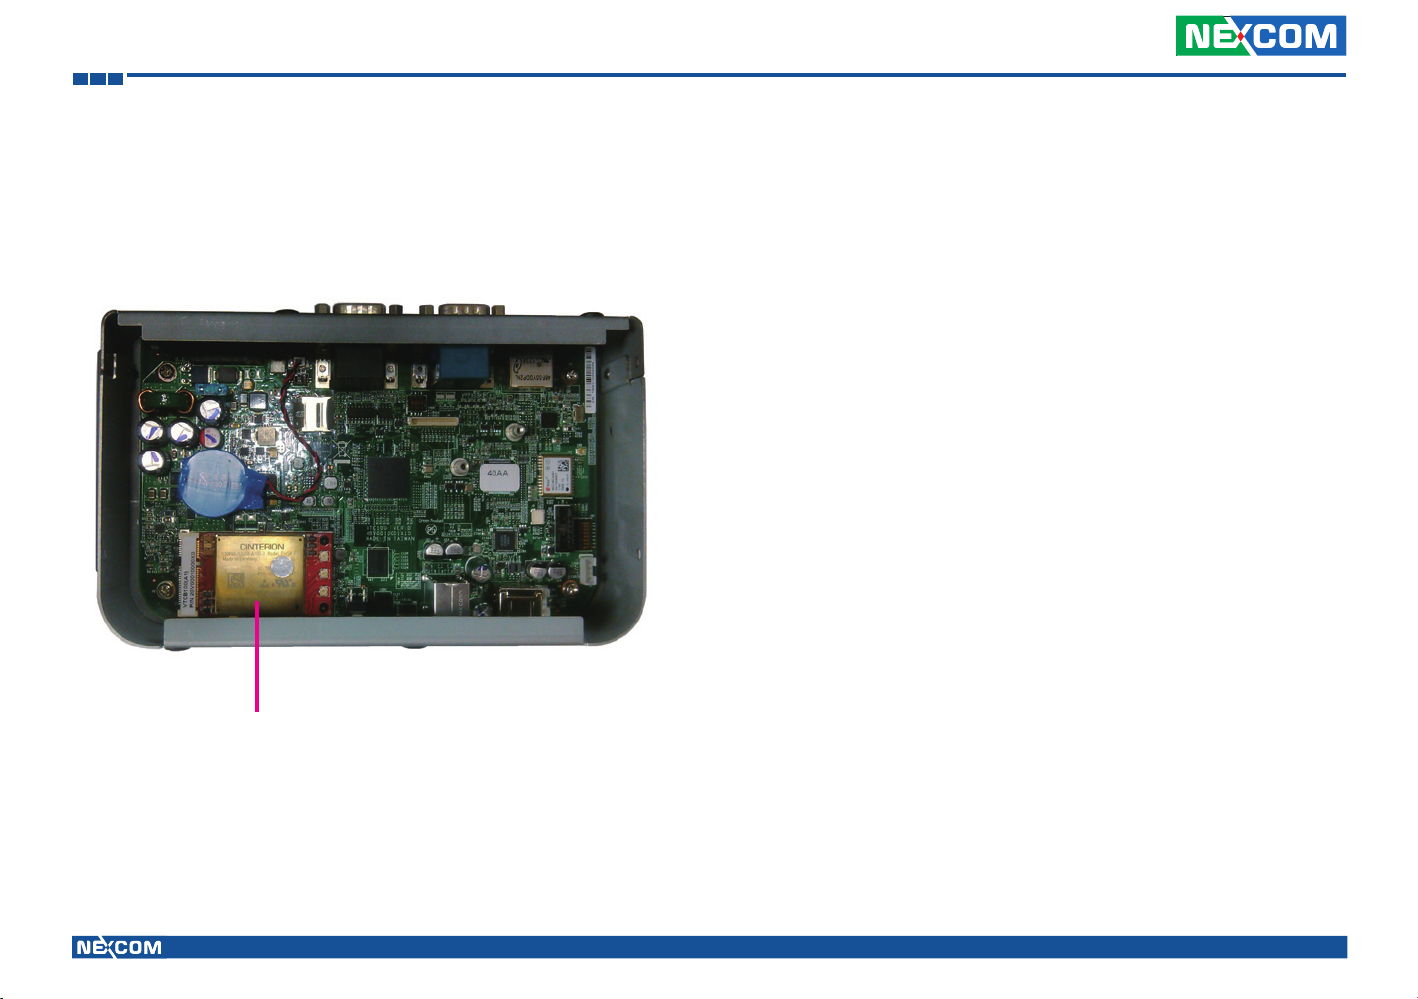
1. The Mini PCI Express slot shown below is used to install a WWAN
communication module such as GPRS, UMTS or HSDPA.
Mini PCI-E slot for WWAN module
installation
2. Insert the module into the Mini PCI Express slot at a 45 degrees angle
until the gold-plated connector on the edge of the module completely
disappears inside the slot.
3. Push the module down then secure it with mounting screws.
4. Attach one end of the RF cable onto the module.
5. Mount the other end of the cable to the antenna mounting hole
located at the front panel of the chassis.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
24
VTC 100 User Manual
Page 38
Chapter 3: System Setup
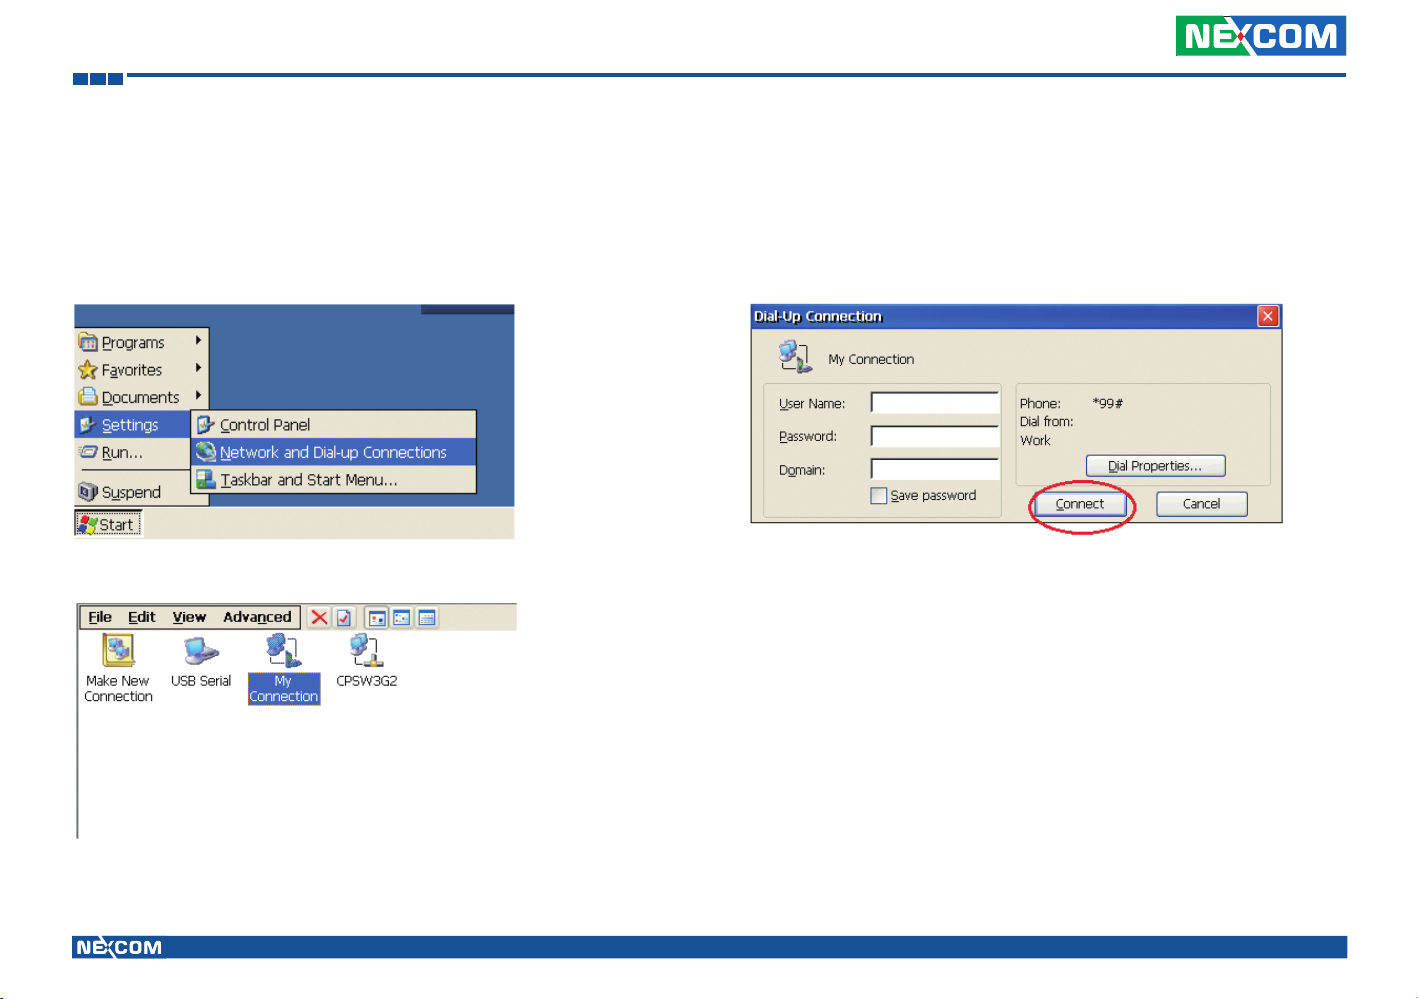
WWAN Dial-up Setting
Configure using default settings
1. Start → Settings → Network and Dial-up Connections
2. Double click on “My Connection”.
3. Click the “Connect” button.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
25
VTC 100 User Manual
Page 39
Chapter 3: System Setup
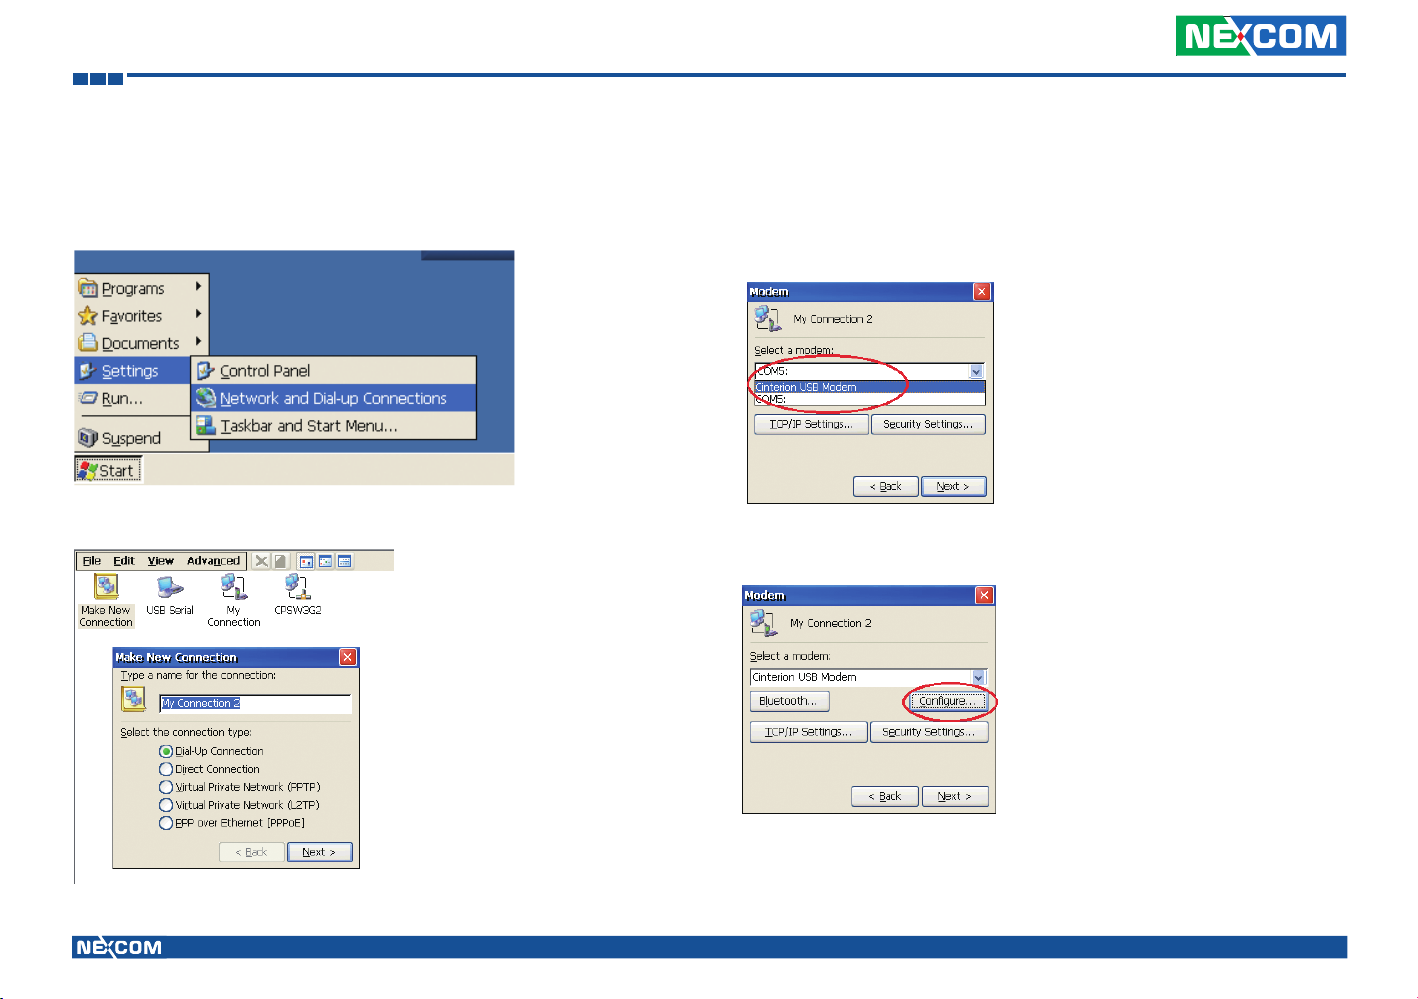
Configure using manual settings
1. Start → Settings → Network and Dial-up Connections
2. Make New Connection → (type name) →Dial-Up Connection → Next
3. Select the WWAN module under the “Select a modem” drop down list,
the example shown below is “Cinterion USB Modem”.
4. Click“Configure”
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
26
VTC 100 User Manual
Page 40
Chapter 3: System Setup
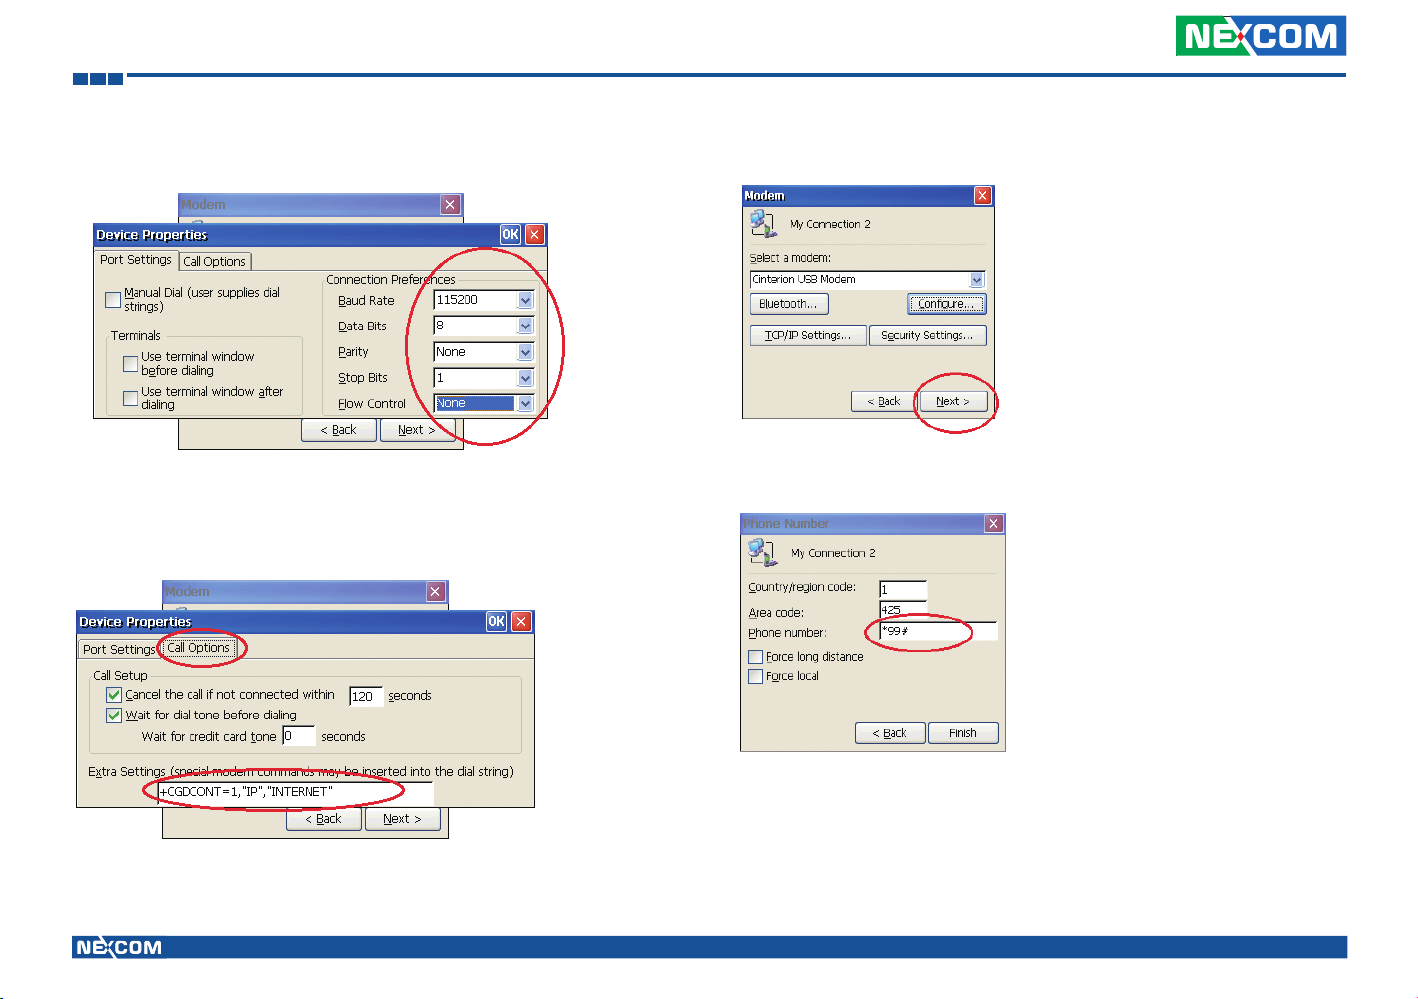
5. Set ”Connection Preferences”as follows.
6. Select “Call Options” and enter { +CGDCONT=1,”IP”,”INTERNET” }
(It depends on your Telecom’s setting).
7. Click“Next”.
8. Enter “*99#” in “Phone number” (It depends on your Telecom’s setting).
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
27
VTC 100 User Manual
Page 41
Chapter 3: System Setup
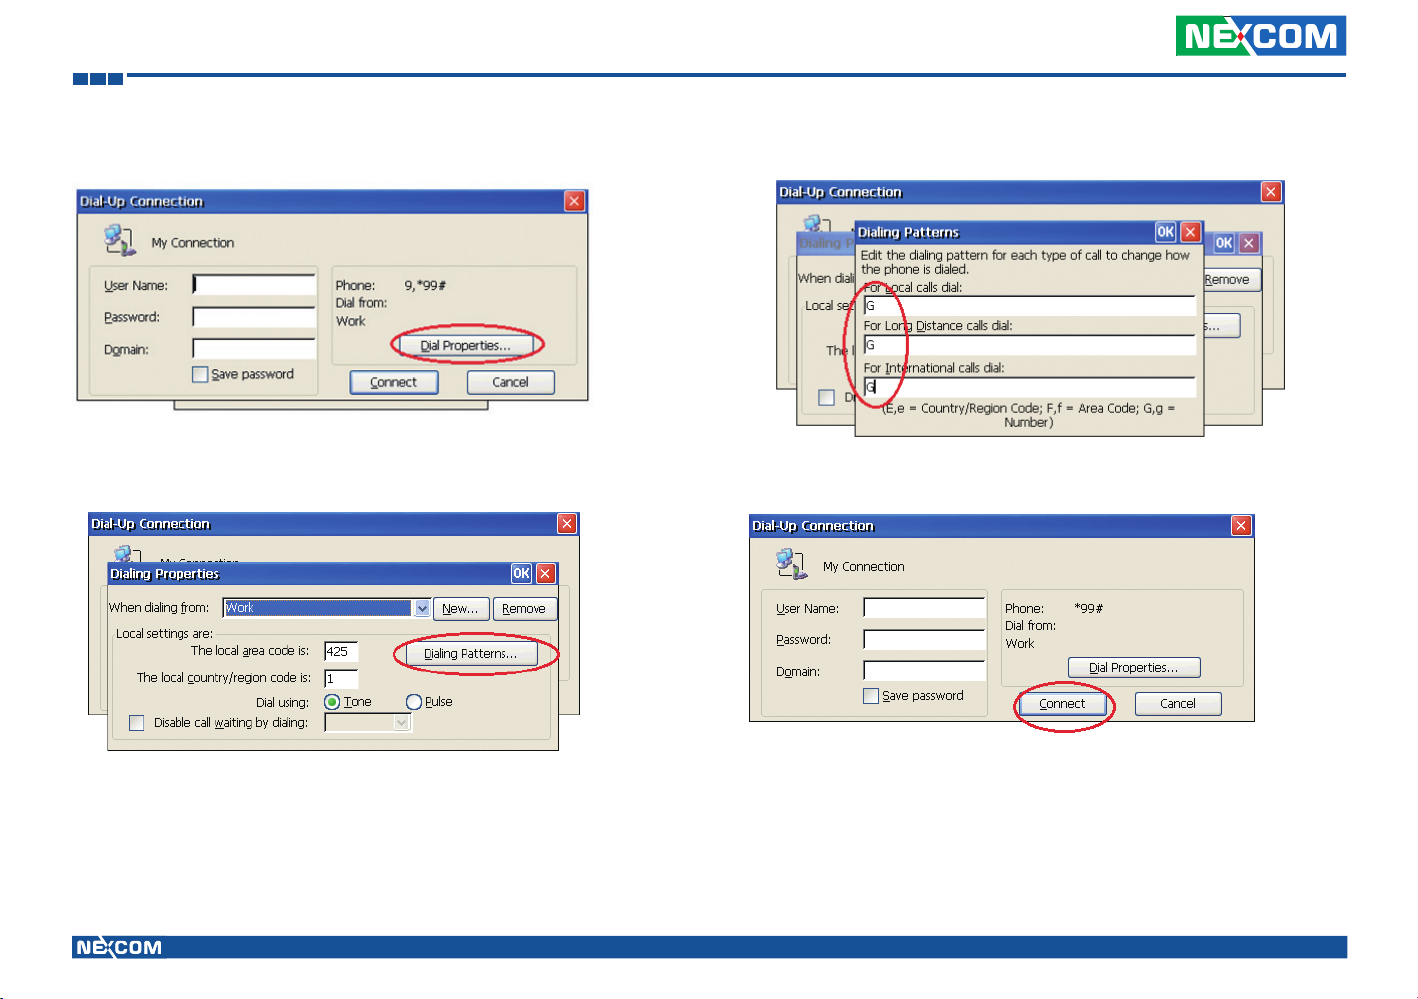
9. Click“Dial Properties”.
10. Click“Dialing Patterns”.
11. Enter “G” (It depends on your Telecom’s setting).
12. Click“Connect”
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
28
VTC 100 User Manual
Page 42
Chapter 3: System Setup
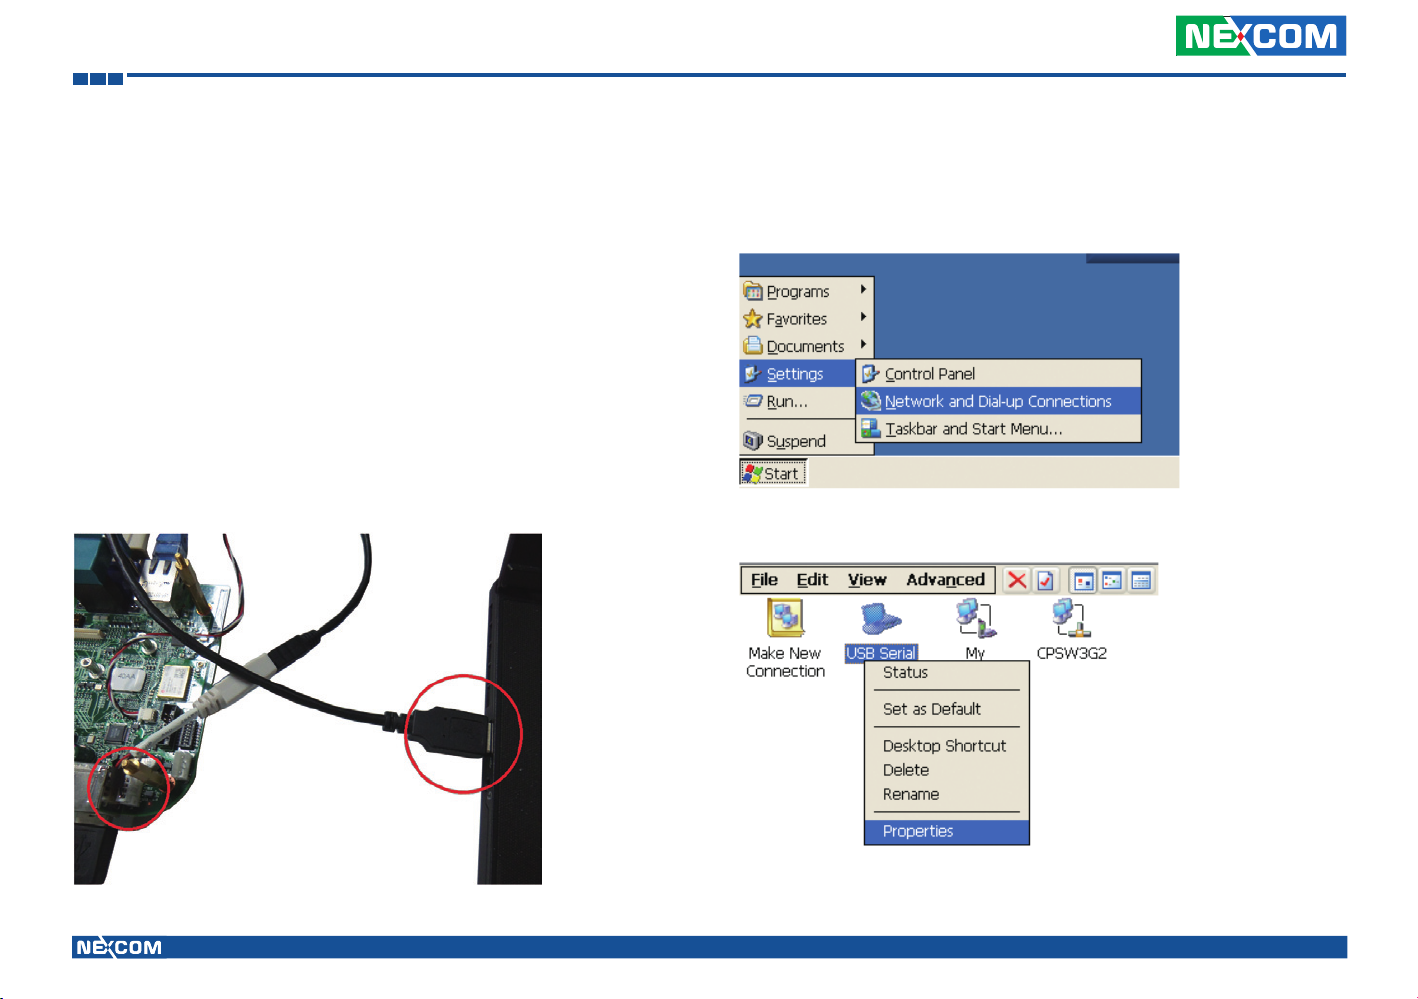
Activesync Setting
Hardware Setup
An optional cable is provided to connect the PC and VTC for activesync
function.
To setup activesync, please follow the following steps:
1. Remove the chassis cover.
2. Plug in this cable to the connector (marked “1”).
3. Connect cable to the USB port on the computer (marked “2”).
VTC Software Setting
1. Start → Settings → Network and Dial-up Connections
2. Highlight and right click “USB Serial” → Properties
1
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
2
29
VTC 100 User Manual
Page 43
Chapter 3: System Setup
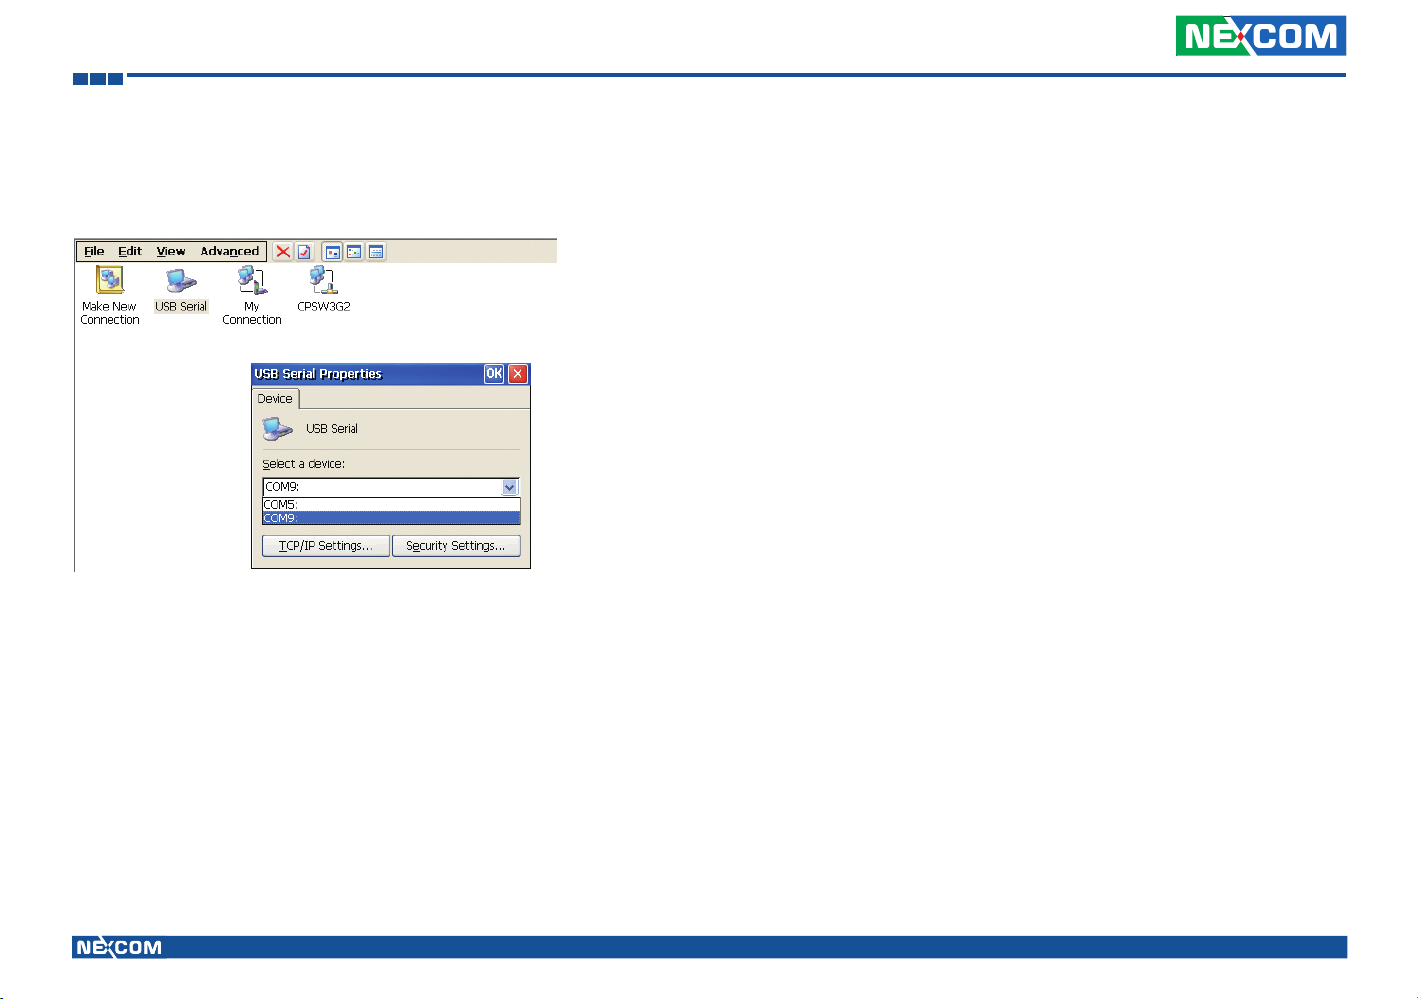
3. Select “COM9” under the “Select a device” drop down list. After
setting is completed, the development software will connect with VTC.
Copyright © 2013 NEXCOM International Co., Ltd. All rights reserved
30
VTC 100 User Manual
Page 44
Appendix A: CAN Module Setup and Command
Appendix A: CAN Module Setup and Command
VTC 100 series offer an option to integrate the CAN BUS module, VIOXCAN01, into VTC 100 system. The form factor of this VIOX-CAN01 is
proprietary and it can support either SAE J1939 or SAE J1708 via connection
in the first time. The maximum VIOX-CAN01 installed in VTC 100 series is
up to three units. Please note they are factory option.
VIOX-CAN01 Setup
When you start connecting VTC 100 device to CAN bus device, you need a
terminal program to send and receive data. To use the terminal program,
please follow the setting below.
(1) Set the proper corresponding “COM” port and its data rate is 9600
(2) Set data bits at 9, stop bit at 1 and no parity bits.
After the setting, you will see the prompt with “>” character. This indicates
that the device is in the idle state and ready to receive characters on the
COM port.
If you do not see prompt string, please reset the device with ATR (reset)
command and then press the return key:
>ATR or >AT R (spaces are optional; and case is in-sensetive).
You can also type HEX code instead:
“41”, “54”, “5A”, “0D”
If you see the strange characters instead of “>”, you may set the incorrect
baud rate. Please check baud rate. If you send the incorrect command,
the device will show a single question mark (“?”) to indicate your input is
not understood. If VTC 100 fails to link to the BUS, it will show “PLEASE
REBOOT”.
Once VTC 100 connect to BUS, it will start to try which protocol is
connected either J1939 or J1708. Once it is determined, it will only accept
the successful protocol next time unless using ATR command to reset it.
This means you can change the protocol by reset command. After the reset
command, please power off the device and turn on it again.
In case, the device cannot find correct protocol after 180 seconds, it will
enter sleeping mode for power saving.
There are several output format available for the different application
including:
(1) Simple Data by ASCII Code
(2) Raw Data
(3) Packaged Messages by ASCII or HEX code.
The default setting is Simple Data Format. The device will send messages
out after it communicates with vehicle successfully. The output format can
be changed via setting the AT command. Please refer the following section
of AT command.
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
31
VTC 100 User Manual
Page 45
Appendix A: CAN Module Setup and Command
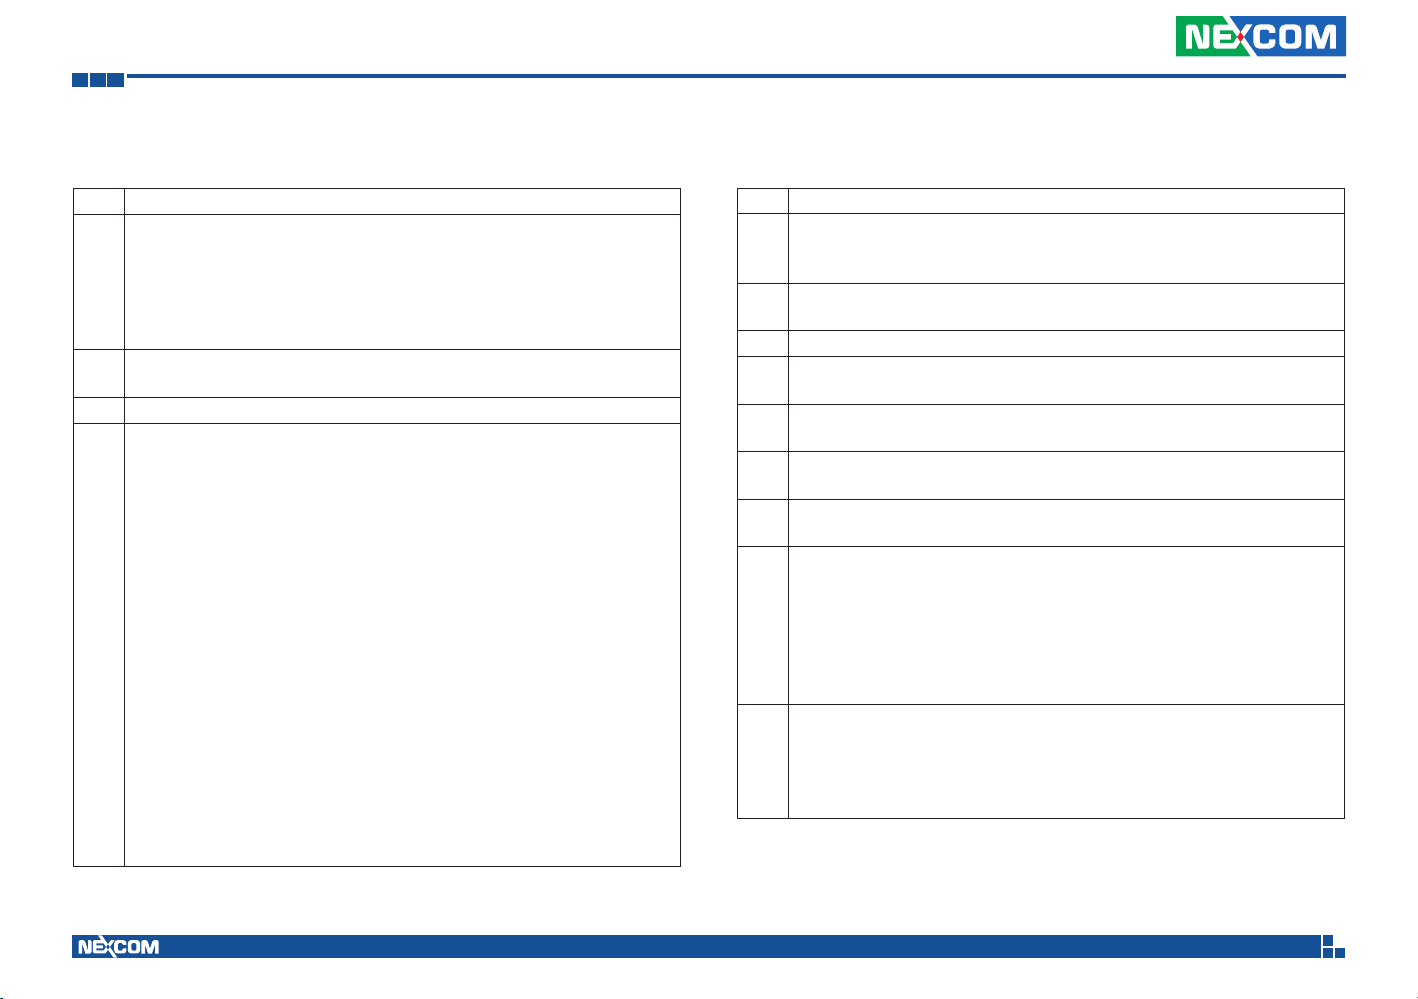
AT Command Summary
@1 AT@1: Display version information
Setting RS232 baud rate. xy is baud rate parameter.
ATBR09: 9600
ATBR19: 19200
BRxy
ATBR38: 38400
ATBR57: 57600
ATBR99: 115200
ATE0: echo off(Default)
Eh
ATE1; echo on
T ATT: Terminate sending. To use ATS will continue it.
ATI : Request vehicle ID, the length is variable.
1.) J1708:
Output format: ASCII code
Byte 0:0x2A
Byte 1: Vehicle ID byte 1
Byte 2: Vehicle ID byte 2
Byte N:Vehicle ID byte N
Byte N+1: Check Sum=Byte 1+Byte2+…….+Byte N
Byte N+2:0x0D
Byte N+3:0x0A
I
N: Max 20
2.)J1939
Byte 0:0x2A
Byte 1: Vehicle ID byte 1
Byte 2: Vehicle ID byte 2
Byte N:Vehicle ID byte N
Byte N+1: Check Sun= Byte1+Byte2 +…..ByteN
Byte N+1:0x0D
Byte N+2:0x0A
N: Max 35
PA ATPA: Print data by ASCII CODE format
ATR: Clear protocol and distance (D1 ,D2)memory, the ATR
PH
command clear current protocol then continue learning next new
protocol.
ATRJ: Request J1939 FMS High Resolution Total Vehicle Distance
RJ
#33~#36
RH ATRH: Request Hino Truck Total vehicle distance (#33~#36)
ATS: Continue auto-send data every 100~200ms. To use ATT
S
will terminal it.
ATSS: Auto- send Simple Data every 100~200 ms.
SS
Refer to Simple Data format Protocol
ATSP: Auto-send Packaging Messages every 100~200 ms.
SP
Refer to Packaging Messages protocol.
ATSR: Auto-send J1939/J1708 Raw Data, Refer to Raw Data
SR
Protocol.
ATX: Request to send data of alternate, data format as
ATS/ATSP command.
For J1939 protocol:
X
Packing1→Packing2→Packing 3→Packing4→Packing5→
Packing6→Packing1
For J1708 protocol:
Packing1→Packing2→Packing 3→Packing4→Packing5→ Packing1
AT#xy: The command will print designated data by ASCII code.
“xy” is data address, it is decimal.
#xy
J1708: 00~53
J1939: 00~99.
EX: AT#01 , to get speed high byte.
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
32
VTC 100 User Manual
Page 46
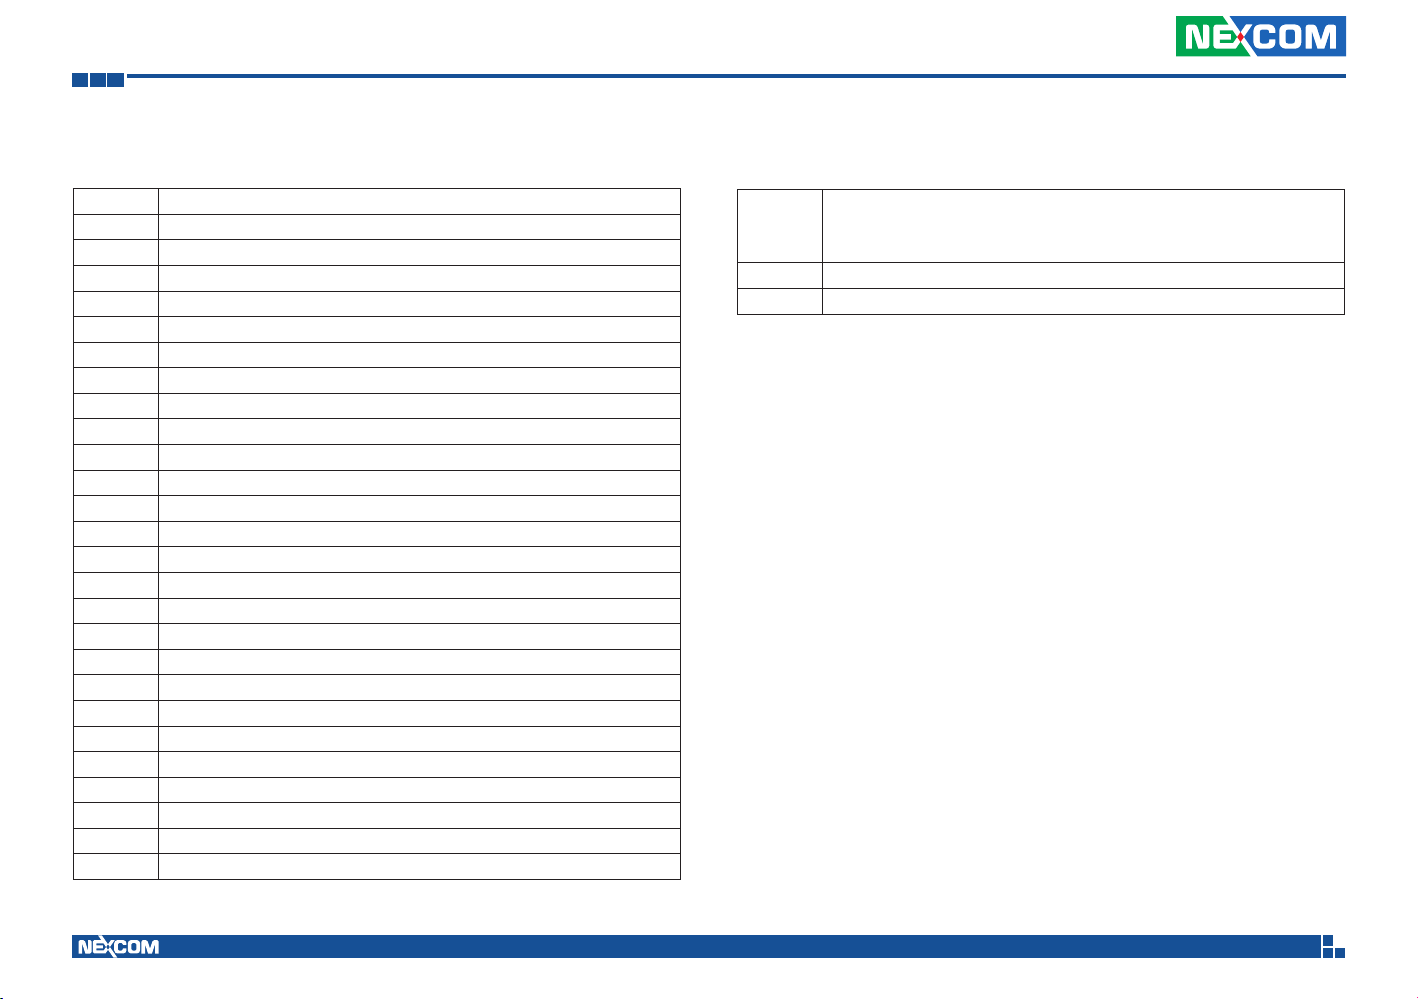
Appendix A: CAN Module Setup and Command
Simple Data Protocol: (ASCII CODE)
Data Description
HEAD @
Byte 0 ,
Byte 1 Speed , (0~255) KM/HR
Byte 2 ,
Byte 3 RPM High Byte (RPMHB)
Byte 4 ,
Byte 5 RPM Low Byte(RPMLB) , RPM=RPMHB*256+RPMLB
Byte 6 ,
Byte 7 Engine Loading, (0~100%)
Byte 8 ,
Byte 9 Battery Voltage (BV), = (BV+100)/10 (v)
Byte 10 ,
Byte 11 Engine Temperature( ET), =ET-40°C
Byte 12 ,
Byte 13 Throttle position 0~100 %
Byte 14 ,
Byte 15 Status , Note 2
Byte 16 ,
Byte 17 MAF (0~255), MAF RATE= MAF * 3;
Byte 18 ,
Byte 19 Distance : D1
Byte 20 ,
Byte 21 Distance: D2
Byte 22 ,
Byte 23 FU, Average Fuel Economy (km/L) =Fu /10
Byte 24 ,
Check sum (odd numbers)= Byte1+ Byte3+Byte5+
Byte 25
Byte7+Byte9+Byte11+ Byte13+ Byte15+Byte17+
Byte19+Byte21+Byte23
Byte 26 Carry return ( 0x0D )
Byte 27 Line feed ( 0x0A)
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
33
VTC 100 User Manual
Page 47
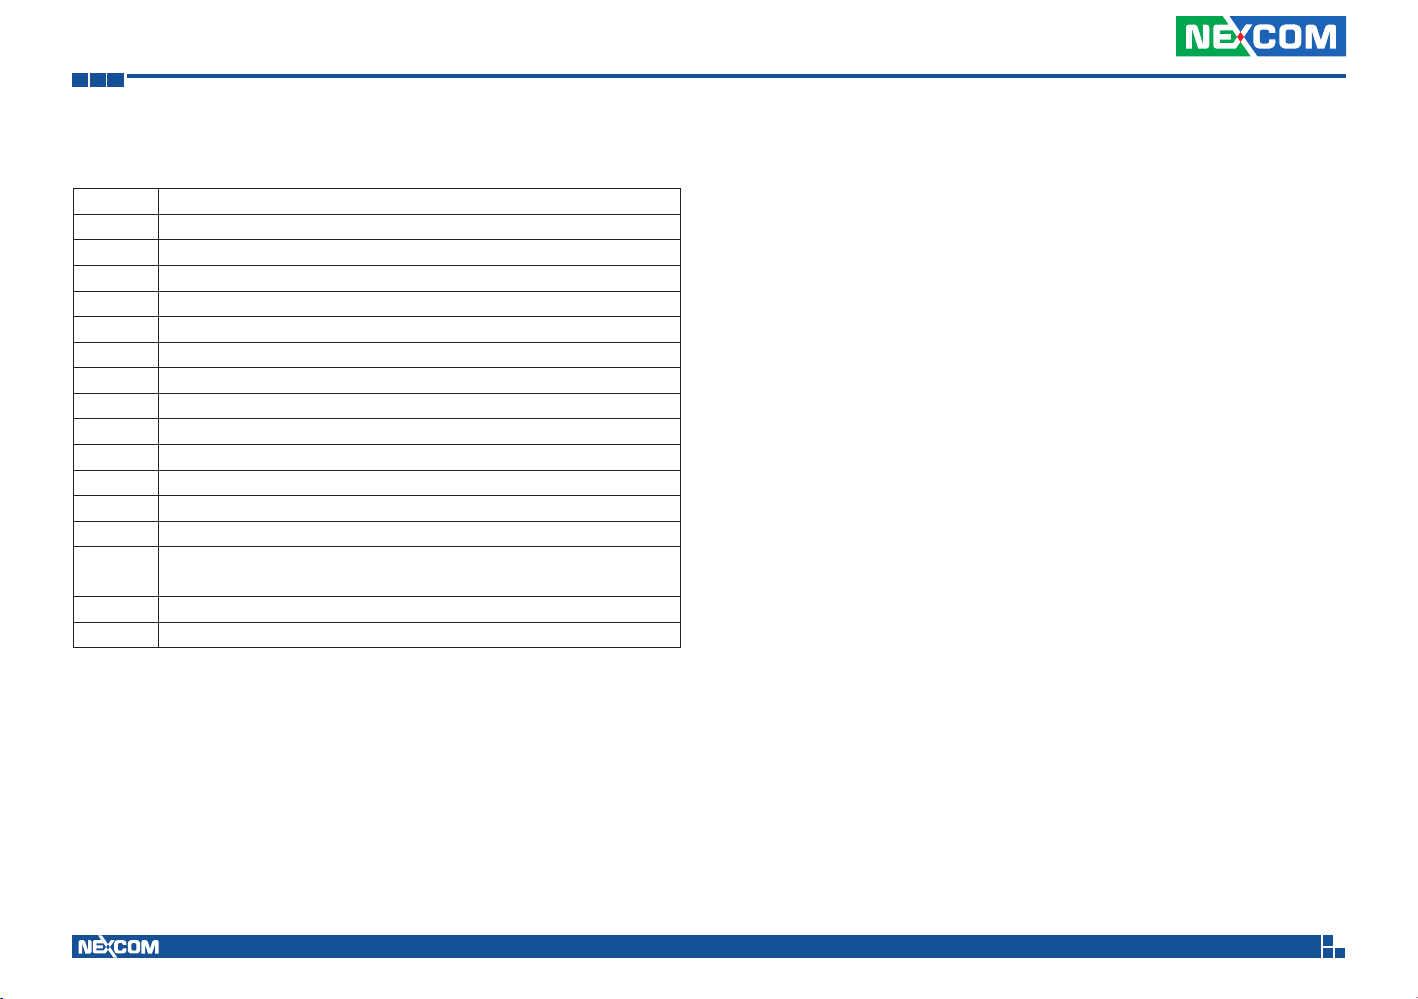
Appendix A: CAN Module Setup and Command
Simple Data Protocol: (HEX CODE)
Data Description
HEAD @ (=0x40)
Byte 1 Speed , (0~255) KM/HR
Byte 2 RPM High Byte (RPMHB)
Byte 3 RPM Low Byte(RPMLB) , RPM=RPMHB*256+RPMLB
Byte 4 Engine Loading, (0~100%)
Byte 5 Battery Voltage (BV), = (BV+100)/10 (v)
Byte 6 Engine Temperature( ET), =ET-40°C
Byte 7 Engine Loading, (0~100%)
Byte 8 Status , Note 2
Byte 9 MAF (0~255), MAF RATE= MAF * 3;
Byte 10 Distance: D1
Byte 11 Distance: D2
Byte 12 FU, Average Fuel Economy (km/L) =Fu /10
Byte 13
Byte 14 Carry return ( 0x0D )
Byte 15 Line feed ( 0x0A)
TCheck sum (odd numbers)= Byte1+ Byte2+Byte3+ Byte4+
Byte5+Byte6+ Byte7+ Byte8+Byte9+ Byte10+ Byte11+Byte12
NOTE:
1.) Data format : ASCII CODE
@ , 7 8 , 0 E , 7 0 , 0 0 ,0 3 , 9 8 , 2 8 , Status ,MAF,D1,D2,Fu,CS
speed=78 km/hr
rpm=0x0E70= 3696
2.) status:
Bit 7:
0: Normal
1: Emergency Braking ( Acceleration < - 6 m/s2 )
Bit 6:
0: Brake OFF
1: Brake ON
Bit 5:
0: Clutch OFF
1: clutch ON
Bit 4:
0: Cruise Control OFF
1: Cruise Control ON
Bit 3:
0: Brake (ON/OFF) unavailable
1: Brake(ON/OFF) available
Bit 2:
0:Clutch (ON/OFF) unavailable
1: Clutch (ON/OFF) available
Bit 1:
0: Cruise Control (ON/OFF) unavailable
1: Cruise Control (ON/OFF) available
Bit 0:
0: NORMAL
1: DTC ON
2.) Distance = D1*256+D2
3.) Average Fuel Economy =Fu /10
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
34
VTC 100 User Manual
Page 48
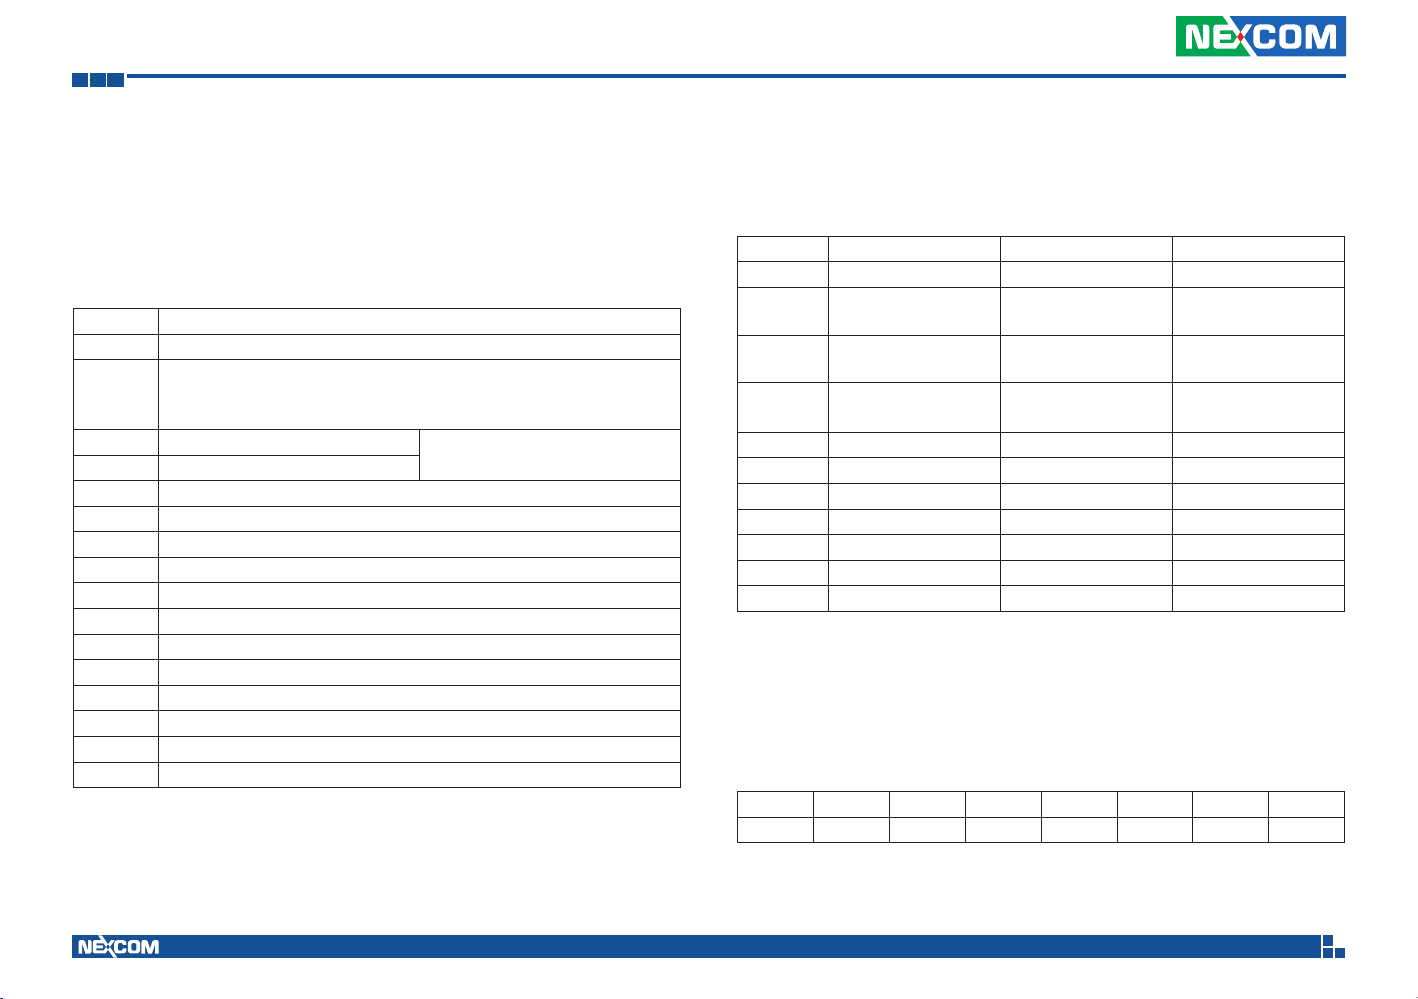
Appendix A: CAN Module Setup and Command
J1939 Raw Data Protocol (HEX CODE)
Support for J1939 PGN / SPN access as defined in the J1939 standards.
This function will report all PGNs and their source node on the J1939
network.
Each SPN under this function should be set to a size of 32 bits.
J1939 Format
Byte 0 @ ( =0x40)
Bit4,3,2: Priority
Byte 1
Byte 2 PDU Format (PF)
Byte 3 PDU Specific (PS)
Byte 4 Source Address
Byte 5 Data1
Byte 6 Data2
Byte 7 Data3
Byte 8 Data4
Byte 9 Data5
Byte 10 Data6
Byte 11 Data7
Byte 12 Data8
Byte 13 Check Sum
Byte 14 0x0D
Byte 15 0x0A
Bit0: Data Page
Bit1,5,6,7:Reversed
PGN
J1708 Raw Data Protocol (HEX CODE)
This function will report all MID and PID that broadcasting on the J1708
network. Its data length is not fixed, please refer to SAEJ1708.
J1939 Format PIDs 128-191 PIDs 0-127
Byte 0 @ (= 0x40) @ (= 0x40) @ (= 0x40)
Byte 1
Byte 2
Byte 3
Byte 4 Data 1 Data2 Check Sum
Byte 5 Data 2 Check Sum 0x0D
Byte 6 …….. 0x0D 0x0A
Byte 7 Data N 0x0A
Byte 8 Check Sum
Byte 9 0x0D
Byte 10 0x0A
PIDs 0-127 describe data parameters that are one byte long.
PIDs 128-191 describe data parameters that consist of two bytes.
PIDs 192-253 The first byte following these PIDs will contain the number of
data parameter bytes.
EX:
MID=128
0x40 0x80 0x15 0x01 0x32 0xC8 0x0D 0x0A
64 128 21 1 50 200 130 10
PID=21 (Engine ECU temperature)
Data=50
Message
identification (MID)
Parameter
identification (PID)
Number of data
bytes
MID MID
PID PID
Data1 Data1
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
35
VTC 100 User Manual
Page 49
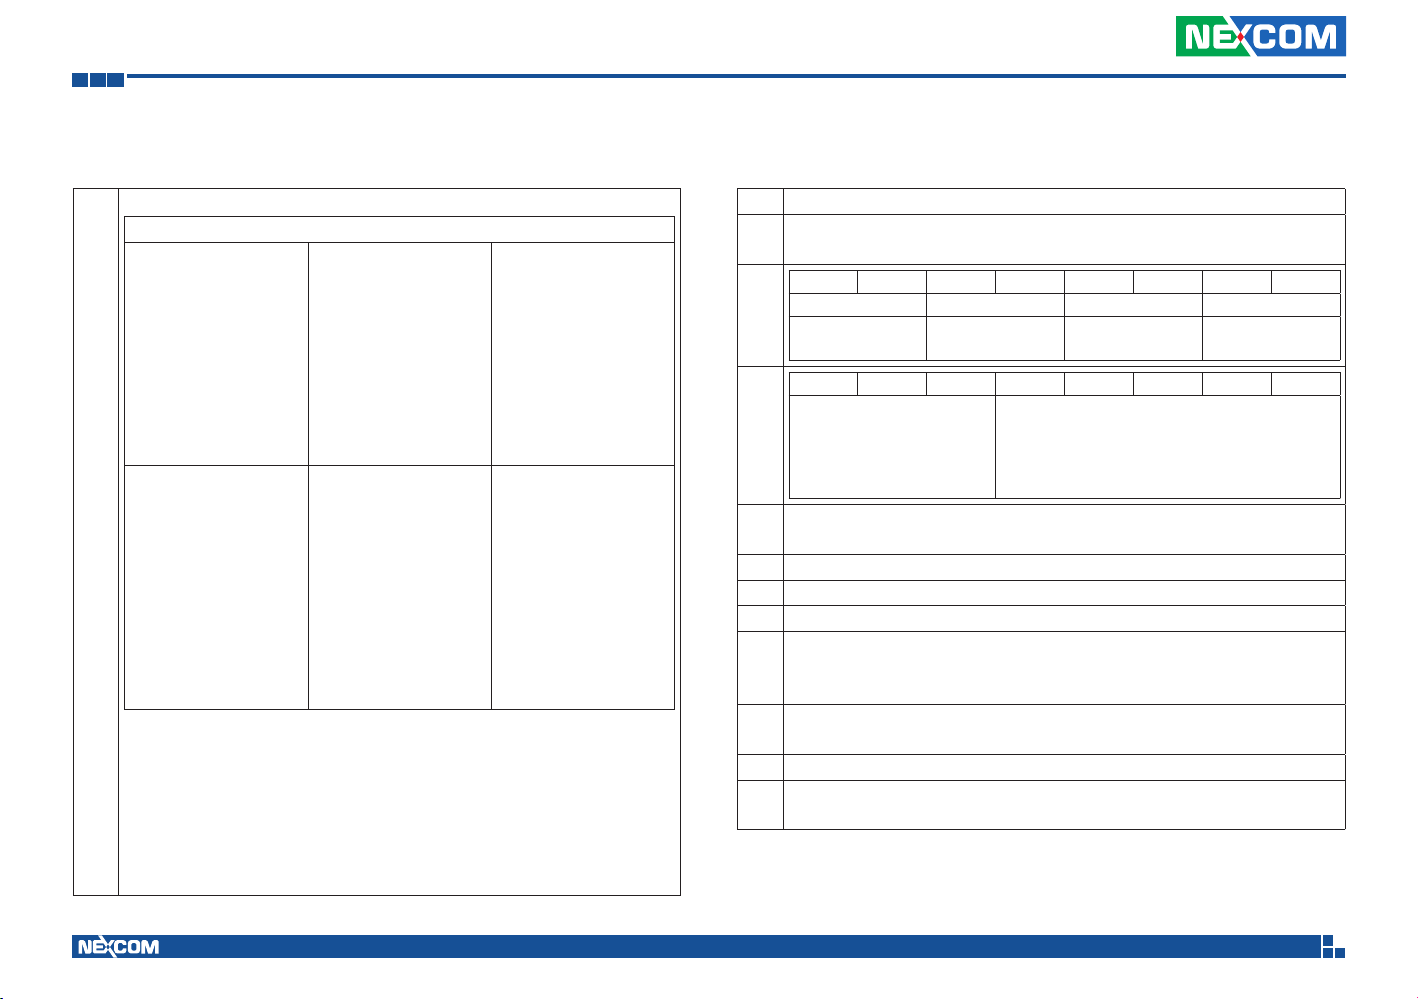
Appendix A: CAN Module Setup and Command
J1939 Packaged Messages Protocol
ATS: send packaged messages by turns.
Response HEX CODE (default) after ATPH command
Packing 1:
Byte 0:“ @” ,( 0x40)
Byte 1: “1”, (0x31)
Byte 2: #00
Byte 3: #01 ......
Byte 19:#17
Byte 20:
Check sum =
Byte2 + ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
Packing 4:
Byte 0:“ @” ,( 0x40)
Byte 1: “a”,(0x41)
Byte 2: #54
S
Byte 3: #55 ......
Byte 19:#71
Byte 20:
Check sum =
Byte2 + ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
Packing 2:
Byte 0: “ @” ,( 0x40)
Byte 1: “2”,(0x32)
Byte 2: #18
Byte 3: #19 ......
Byte 19:#35
Byte 20:
Check sum = Byte2
+ ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
Packing 5:
Byte 0: “ @” ,( 0x40)
Byte 1: “b”,(0x42)
Byte 2: #72
Byte 3: #73 ......
Byte 19:#89
Byte 20:
Check sum = Byte2
+ ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
Packing 3:
Byte 0: “ @” ,( 0x40)
Byte 1: “3”,(0x33)
Byte 2: #36
Byte 3: #37 ......
Byte 19:#53
Byte 20:
Check sum = Byte2
+ ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
Packing 6:
Byte 0: “ @” ,( 0x40)
Byte 1: “c”,(0x43)
Byte 2: #90
Byte 3: #91 ......
Byte 14:#102
Byte 19:0
Byte 20:
Check sum = Byte2
+ ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
NOTE :
1. AT#00 ~ AT#102 respond ASCII CODE format data.
2. Packing 6, Byte15~Byte19 not defined (set to ”0”)
3. After ATPA command, byte 21& 22 were ignored.
4. This is the common J1939 measurement overview showing which
measurements are available. Note that not all measurements are
supported by the individual engines.
#00 Speed Low Byte (SLB)
Speed High Byte (SHB)
#01
speed=(SHB*256+SLB)/256
B7 B6 B5 B4 B3 B2 B1 B0
Clutch switch Brake switch NOT USED Cruise control active
#02
00 = pedal released
01 = pedal depressed
B7 B6 B5 B4 B3 B2 B1 B0
B7: Emergency brake(-6m/s2)
B6: speed up (6m/s2)
#03
B5: Double Emergency brake
(over -12m/s2)
1: Enable, 0:Disable
0.4 % / Bit gain, Accelerator Pedal Position(APP) , 0 to 100 %
#04
APP= Data* 0.4
00 = pedal released
01 = pedal depressed
PTO state
00000 = off/disabled
00101 = Set
11111 = not available
00 = switched off
01 = switched on
#05 Engine Total Fuel used 0,5 L / Bit gain , ETF1
#06 Engine Total Fuel used 0,5 L / Bit gain , ETF2
#07 Engine Total Fuel used 0,5 L / Bit gain , ETF3
Engine Total Fuel used 0,5 L / Bit gain , ETF4
#08
Engine Total Fuel used
=((ETF4*256*256*256)+(ETF3*256*256)+(ETF2*256)+ETF1)*0.5
Fuel Level (FL) , 0 to 100 %, 0.4 %/bit
#09
Fuel Level=FL*0.4
#10 RPM Low byte, RL
RPM High byte, RH
#11
RPM= (RH*256+ RL)* 0.125
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
36
VTC 100 User Manual
Page 50
Appendix A: CAN Module Setup and Command
B7 B6 B5 B4 B3 B2 B1 B0
NOT USED Engine Starter Mode
B7: 1, Total Vehicle Distance is provided by vehicle ECU
0, Total Vehicle Distance is calculation value
B3~B0:
0000 start not requested
0001 starter active, gear not engaged
0010 starter active, gear engaged
0011 start finished; starter not active after having been actively
engaged ?
#12
(after 50ms mode goes to 0000)?
0100 starter inhibited due to engine already running
0101 starter inhibited due to engine not ready for start (preheating)
0110 starter inhibited due to driveline engaged
0111 starter inhibited due to active immobilizer
1000 starter inhibited due to starter over-temp
1001-1011 Reserved
1100 starter inhibited - reason unknown
1101 error
1111 not available
Axle location The value 0xFF indicates not available.
B7 B6 B5 B4 B3 B2 B1 B0
Axle location Bit-mapped position
number counting front to back facing
forward
#13
F = not available
position number, counting front to
back on the vehicle. B7,B6,B5,B4
Axle location Bit-mapped position
number counting front to back facing
forward.
Tire location Bit-mapped counting left
to right facing forward
F = not available
The low order 4 bits represent a
position number, counting left to right
when facing in the direction of normal
vehicle travel
#14 Axle weight 0.5 kg / Bit gain (Low Byte),AWL
Axle weight 0.5 kg / Bit gain (High Byte), AWH
#15
Weight=(AWH*256+AWL)*0.5
#16 Engine total hours of Operation, EH1
#17 Engine total hours of Operation, EH2
#18 Engine total hours of Operation, EH3
Engine total hours of Operation, EH4
#19
Accumulated
time=((EH4*256*256*256)+(EH3*256*256)+(EH2*256)+EH1)*0.05
#20
Vehicle identification number, aabbccddeeffgghh (If the Vehicle ID
|
contains more than 8 Bytes then #20~#27 are “00”, please use ATI
#27
command to request.
#20 aa
#21 bb
#22 cc
#23 dd
#24 ee
#25 ff
#26 gg
#27 hh
#28 Engine Percent Load At Current Speed ( 0~125 %)
#29
SW-version supported for trucks, Version number in the format
|
ab.cd where this byte represents ASCII code #29 : “a” , #30: ‘b’,
#32
#31:’c’ , #32:’d’
#33
High Resolution Total Vehicle Distance, 5 m/bit, 0 to 21,055,406 km
|
=((D4*256*256*256)+(D3*256*256)+(D2*256)+D1)*0.005 (KM)
#36
#33 D1
#34 D2
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
37
VTC 100 User Manual
Page 51
Appendix A: CAN Module Setup and Command
#35 D3
#36 D4
#37
The distance which can be traveled by the vehicle before the next
|
service inspection is required
#38
SERV=(V2*256+V1)*5-160635 (KM)
#37 V1
#38 V2
B7 B6 B5 B4 B3 B2 B1 B0
Vehicle
motion(B7,B6):
00 = Vehicle
#39
motion not
detected
01 = vehicle
motion detected
B7 B6 B5 B4 B3 B2 B1 B0
Vehicle Overspeed Driver 1 card Driver 1 time related state
Driv. 2 working stat
state (B5,B4,B3)
000 = Rest
001 = Driver available
010 = Work
011 = Drive
110 = Error
111 = not available
G
°
Driv. 1 working state
(B2,B1,B0):
000 = Rest
001 = Driver available
010 = Work
011 = Drive
110 = Error
111 = not avaiable
Vehicle Over speed (B7,B6)°GIndicates whether the vehicle is
exceeding the legal speed limit set in the tachograph.
00 = No over speed
01 = Over speed Driver 1 card (B5,B4)
00 = Card not present
01 = Card present
Driver 1 time related state (B3,B2,B1,B0)
#40
approaches or exceeds working time limits (or other limits).
GIndicates if the driver
°
0000 = normal
0001 = 15 min bef. 4.5 h
0010 = 4.5 h reached
0011 = 15 min bef. 9 h
0100 = 9 h reached
0101 = 15 min bef. 16 h
0110 = 16h reached
1110 = Error
1111 = not available
B7 B6 B5 B4 B3 B2 B1 B0
Driver 2 time related state (B3,B2,B1,B0)
GIndicates if the driver approaches or
exceeds working time limits (or other limits).
0000 = normal
0001 = 15 min bef. 4.5 h
0010 = 4.5 h reached
0011 = 15 min bef. 9 h
0100 = 9 h reached
0101 = 15 min bef. 16 h
0110 = 16h reached
1110 = Error
1111 = not available
Handling
information
#41
NOT USED
Direction indicator
Driver 2 card (B5,B4)
00 = Card not
present
01= Card present
B7 B6 B5 B4 B3 B2 B1 B0
Tachgraph
performance
Direction indicator (B7,B6)°G
00 = Forward
01 = Reverse Tachgraph performance (B5,B4)
#42
00 = Normal performance
01 = Performance analysis Handling information (B3,B2)
00 = no handling information
01 = handling information System event (B1,B0)
00 = no tachogr. Event
01 = tachogr. Event
#43
Tachogr. vehicle speed 1/256 km/h Bit gain
|
Speed= ((VS2*256)+VS1)/256
#44
#43 VS1
#44 VS2
°
System event
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
38
VTC 100 User Manual
Page 52
Appendix A: CAN Module Setup and Command
Engine Coolant Temperature(ECT) , -40 to 210 deg C
#45
ECT=data-40°C
Engine Turbocharger Boost Pressure(ETBP), 2 kPa/bit , 0~500 KPA
#46
ETPB=data *2 (KPA)
Engine Intake Manifold 1 Temperature(EIMT) , -40 to 210 deg C
#47
EIMT=data-40°C
Bit7,6 Anti-Lock Braking (ABS) Active
00 - ABS passive but installed
01 - ABS active
#48
10 – Reserved
G
°
11 - Not available
Bit5~Bit0: Resvered.
Brake Pedal Position (BPP), 0.4 %/bit, 0~100%
#49
BPP=data*0.4 (%)
Parking and/or Trailer Air Pressure(PTAP), 8 kPa/bit
#50
PTAP=data *8 (KPA)
Service Brake Air Pressure Circuit #1 (SBAPC1), 8 kPa/bit
#51
SBAPC1=data*8 (KPA)
Service Brake Air Pressure Circuit #2 (SBAPC2), 8 kPa/bit
#52
SBAPC2=data*8 (KPA)
Parking Brake Switch
#53
00 = Parking brake not set
01 = Parking brake set
Bit 1 ,Bit 0: Diagnostics supported
00 = diagnostics is not supported
01 = diagnostics is supported
10 = reserved
11 = don´t care
Bit 3 ,Bit 2: Requests supported
#54
00 = request is not supported
01= request is supported
10 = reserved
11 = don´t care
Bit4~Bit7:Resvered
Ambient Air Temperature: Temperature of air surrounding vehicle.
#55
AAT=(AATH* 256+AATL)*0.03125 -273 deg C
|
#55: AATL
#56
#56: AATH
Door Control 1:
Bit 7,Bit6: Status 2 of doors
00 = all bus doors disabled
01 = at least 1 bus door enabled
10 = error
11 = not available
Bit 5, Bit4: Ramp/Wheel chairlift
00 = inside bus
#57
01 = outside bus
10 = Error
11 = not available
Bit 3,2,1,0 : Position of doors
0000 = at least 1 door is open
0001 = closing last door
0010 = all doors closed
1110 = Error
1111 = not available
Door Control 2, #58~#65
Lock Status:
locked→doors cannot be operated by the driver or a passenger
unlocked→door may be operated by the driver or a passenger
#58
Open Status:
|
closed→door is completely closed
#56
open→door is not completely closed
Enable Status:
disabled→door cannot be opened by a passenger
enabled→door can be opened by a passenger
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
39
VTC 100 User Manual
Page 53
Appendix A: CAN Module Setup and Command
Bit 7, Bit 6: Lock
Status Door 2
#58
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit 7, Bit 6: Open
Status Door 3
#59
00 = Closed
01 = Open
10 = Error
11 = Not available
Bit 7, Bit 6: Enable
Status Door 4
#60
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
Bit 7, Bit 6: Lock
Status Door 6
#61
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit 7, Bit 6: Open
Status Door 7
#62
00 = Closed
01 = Open
10 = Error
11 = Not available
B7 B6 B5 B4 B3 B2 B1 B0
Bit 5,Bit 4: Enable
Status Door 1
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
B7 B6 B5 B4 B3 B2 B1 B0
Bit 5, Bit 4: Lock
Status Door 3
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
B7 B6 B5 B4 B3 B2 B1 B0
Bit 5, Bit 4: Open
Status Door 4
00 = Closed
01 = Open
10 = Error
11 = Not available
B7 B6 B5 B4 B3 B2 B1 B0
Bit 5, Bit 4: Enable
Status Door 5
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
B7 B6 B5 B4 B3 B2 B1 B0
Bit 5, Bit 4: Lock
Status Door 7
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit 3,Bit 2: Open
Status Door 1
00 = Closed
01 = Open
10 = Error
11 = Not available
Bit 3, Bit 2: Enable
Status Door 2
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
Bit 3, Bit 2: Lock
Status Door 4
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit 3, Bit 2: Open
Status Door 5
00 = Closed
01 = Open
10 = Error
11 = Not available
Bit 3, Bit 2: Enable
Status Door 6
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
Bit 1,Bit 0: Lock
Status Door 1
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit 1, Bit 0: Open
Status Door 2
00 = Closed
01 = Open
10 = Error
11 = Not available
Bit 1, Bit 0: Enable
Status Door 3
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
Bit 1, Bit 0: Lock
Status Door 5
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit1, Bit 0: Open
Status Door 6
00 = Closed
01 = Open
10 = Error
11 = Not available
B7 B6 B5 B4 B3 B2 B1 B0
Bit 7, Bit 6: Enable
Status Door 8
#63
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
Bit 7, Bit 6: Lock
Status Door 10
#64
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit 3, Bit 2: Enable
Status Door 10
#65
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
B7 B6 B5 B4 B3 B2 B1 B0
B7 B6 B5 B4 B3 B2 B1 B0
Bit 5, Bit 4: Open
Status Door 8
00 = Closed
01 = Open
10 = Error
11 = Not available
Bit 5, Bit 4: Enable
Status Door 9
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
Bit1, Bit 0: Open
Status Door 10
00 = Closed
01 = Open
10 = Error
11 = Not available
Time / Date:
#66 : Second=data * 0.25
#66
#67 : Minutes=data
|
#68 : Hours=data
#69 : Month=data
#71
#70 : Day=data * 0.25
#71 : Year=data-1985 (1985 to 2235 years)
Alternator Status
B7 B6 B5 B4 B3 B2 B1 B0
Bit 7, Bit6:
Alternator Status 4
#72
00 = not charging
01 = charging
10 = error
11 = not available
Bit 5, Bit4:
Alternator Status 3
00 = not charging
01 = charging
10 = error
11 = not available
Bit 3, Bit 2: Lock
Status Door 8
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit 3, Bit 2: Open
Status Door 9
00 = Closed
01 = Open
10 = Error
11 = Not available
Bit 3, Bit 2:
Alternator Status 2
00 = not charging
01 = charging
10 = error
11 = not available
Bit1, Bit 0: Enable
Status Door 7
00 = Disabled
01 = Enabled
10 = Error
11 = Not available
Bit1, Bit 0: Lock
Status Door 9
00 = Unlocked
01 = Locked
10 = Error
11 = Not available
Bit 1, Bit 0:
Alternator Status 1
00 = not charging
01 = charging
10 = error
11 = not available
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
40
VTC 100 User Manual
Page 54
Appendix A: CAN Module Setup and Command
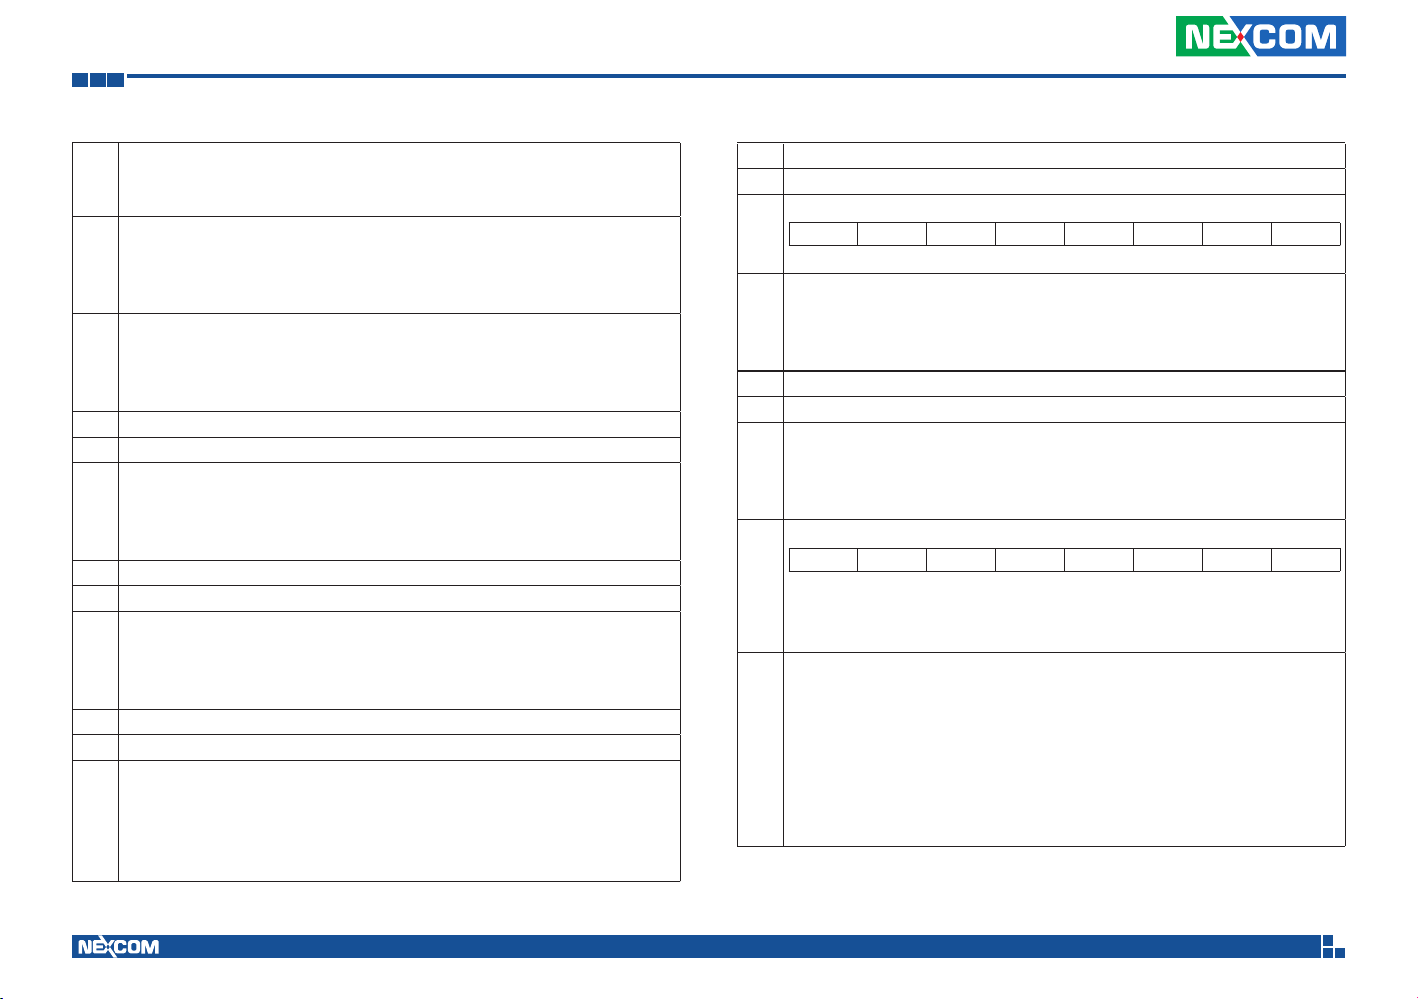
Selected Gear = data -125negative gear are reverse gears
#73
00000000 = neutral
11111011 = park
Current Gear=data-125
negative gear are reverse gears
#74
00000000 = neutral
11111011 = park
Bellow Pressure Front Axle Left
#75
Information of the pressure of the air suspension bellow at the left
|
side of the front axle
#76
Pressure= ((BPFAL2*256)+BPFAL1)* 0.1 ,KPA
#75 BPFAL1
#76 BPFAL2
Bellow Pressure Front Axle Right
#77
Information of the pressure of the air suspension bellow at the left
|
side of the front axle
#78
Pressure= ((BPFAR2*256)+BPFAR1)* 0.1 ,KPA
#77 BPFAR1
#78 BPFAR2
Bellow Pressure Rear Axle Left
#79
Information of the pressure of the air suspension bellow at the left
|
side of the front axle
#80
Pressure= ((BPRAL2*256)+BPRAL1)* 0.1 ,KPA
#79 BPRAL1
#80 BPFAR2
Bellow Pressure Rear Axle Right
#81
Information of the pressure of the air suspension bellow at the left
|
side of the
#82
front axle
Pressure= ((BPRAR2*256)+BPRAR1)* 0.1 ,KPA
#81 BPRAL1
#82 BPFAR2
Driver’s Identification (Driver 1 & Driver 2 identification)
#83
#83 #84 #85 #86 #87 #88 #89 #90
|
#90
The driver ID is only available if a digital tachograph is present
Engine Fuel Rate (EFR). Amount of fuel consumed by engine per
#91
liter of hour.
|
EFR=(EFR2*256+EFR1)* 0.05 , L/h
#92
Data Range: 0 to 3,212.75 L/h
#91 EFR1
#92 EFR2
Engine Instantaneous Fuel Economy(EIFE). Current fuel economy at
#93
current vehicle velocity.
|
EIFE=(EIFE2*256+EIFE1) / 512 , km/L
#94
Data Range: 0 to 125.5 km/L
FMS Tell Tale Status
#95
#
#95 #96 #97 #98 #99 #100 #101 #102
|
The Tell Tale Status information is derived from information
102
displayed to the
driver’s dashboard.
Bit 3,2,1,0: Telltale Block ID
Bit 7,6,5,4: Telltale Status 1
1000 = off
1001 = Cond. Red
#95
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
41
VTC 100 User Manual
Page 55
Appendix A: CAN Module Setup and Command
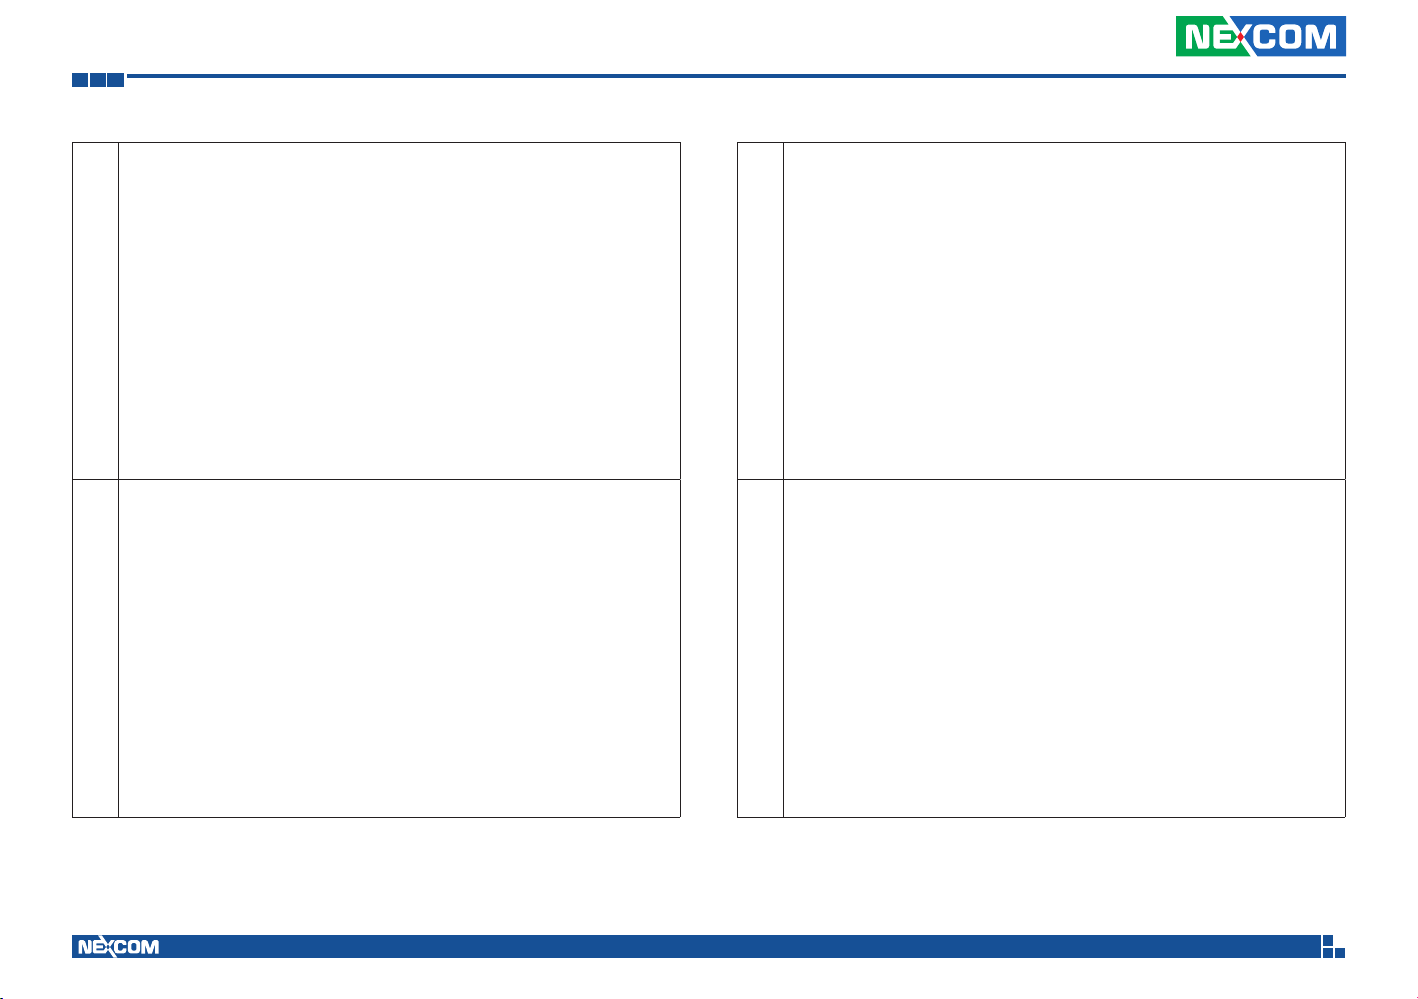
Bit 3,2,1,0: Telltale Status 2
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
#96
Bit 7,6,5,4: Telltale Status 3
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
Bit 3,2,1,0: Telltale Status 4
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
#97
Bit 7,6,5,4: Telltale Status 5
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
Bit 3,2,1,0: Telltale Status 6
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
#98
Bit 7,6,5,4: Telltale Status 7
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
Bit 3,2,1,0: Telltale Status 8
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
#99
Bit 7,6,5,4: Telltale Status 9
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
42
VTC 100 User Manual
Page 56
Appendix A: CAN Module Setup and Command
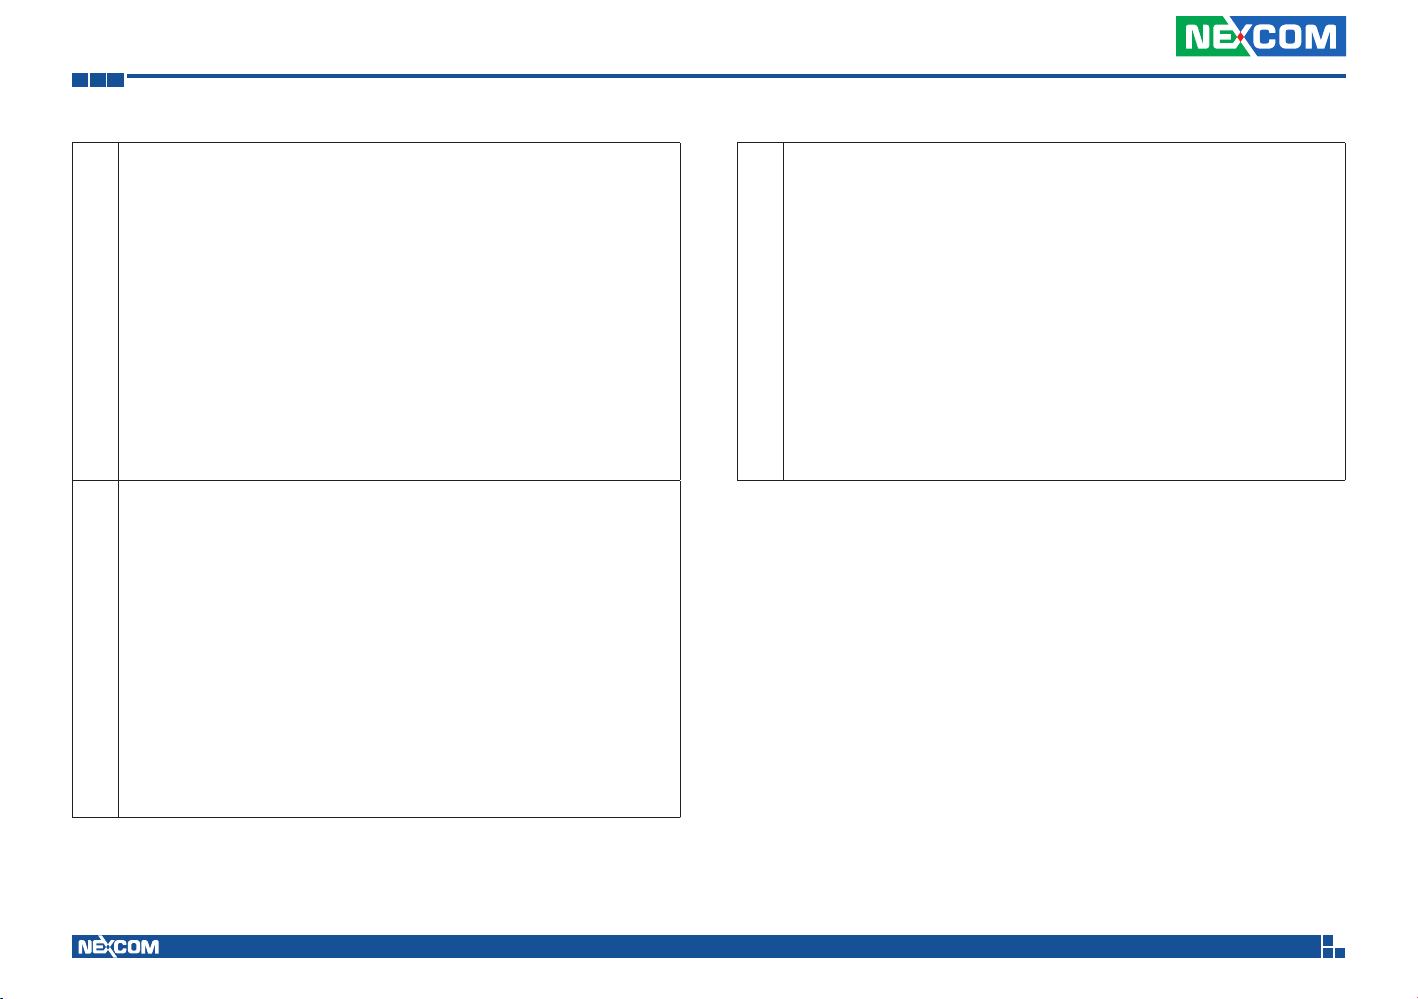
Bit 3,2,1,0: Telltale Status 10
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
#
100
Bit 7,6,5,4: Telltale Status 11
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
Bit 3,2,1,0: Telltale Status 12
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
#
101
Bit 7,6,5,4: Telltale Status 13
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
Bit 3,2,1,0: Telltale Status 14
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
#
102
Bit 7,6,5,4: Telltale Status 15
1000 = off
1001 = Cond. Red
1010 = Cond. Yellow
1011 = Cond. Info
1100–1110 = Reserved
1111 = not available
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
43
VTC 100 User Manual
Page 57
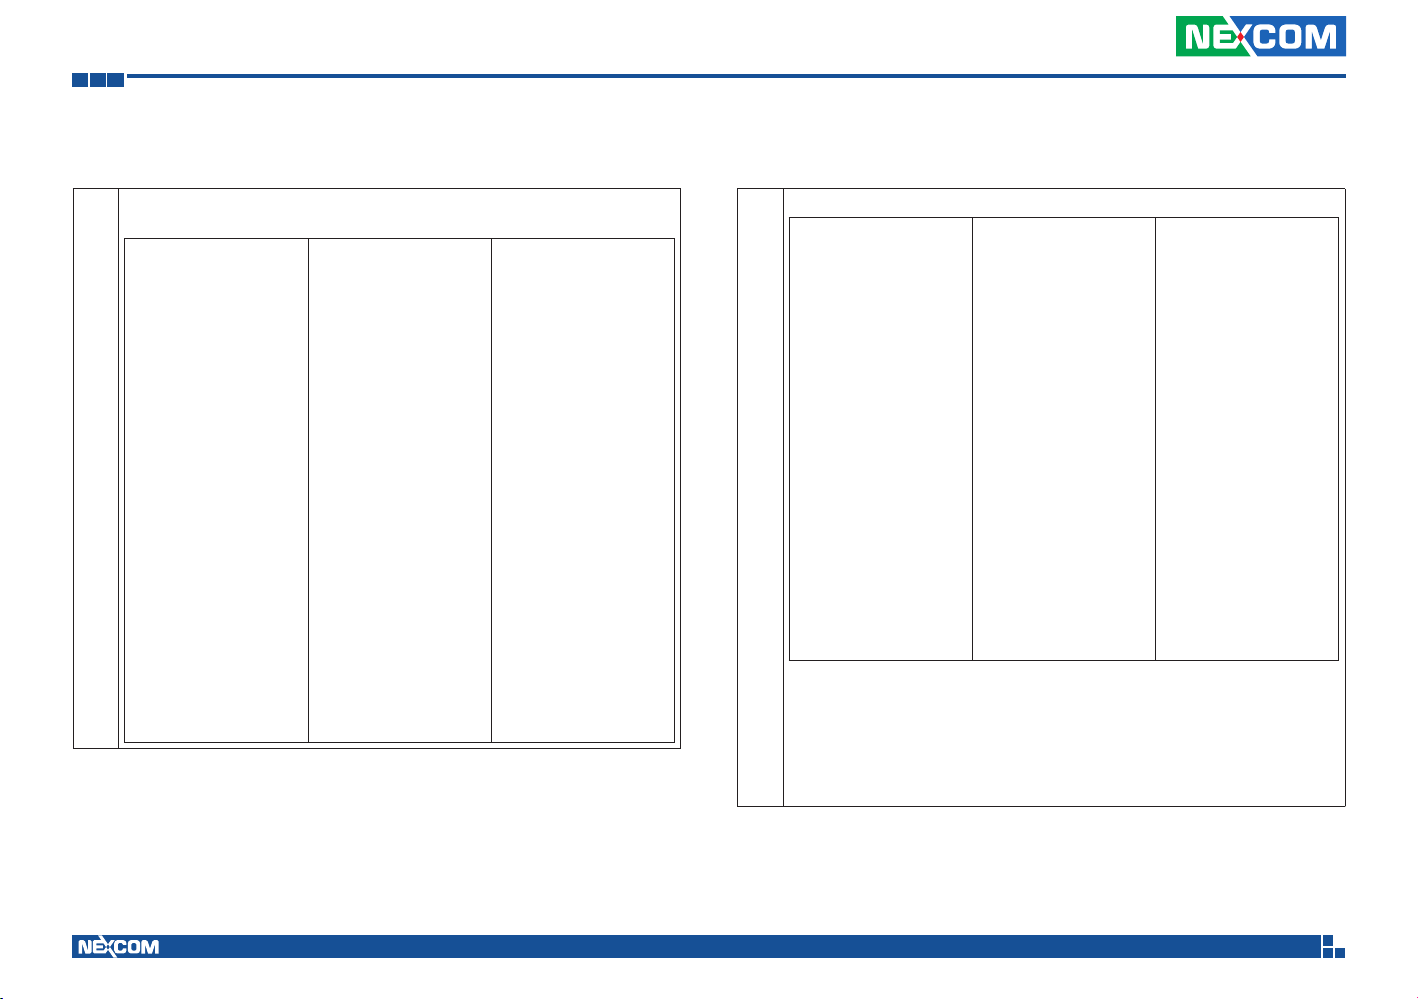
Appendix A: CAN Module Setup and Command
J1708 Packaged Messages Protocol
Once AT1708 SLEEP, it can wake it up.
Start to send data by 3 packing, response HEX CODE
Packing 1:
Byte 0: “ @” , 0x40;
Byte 1: 4
Byte 2: #00
Byte 3: #01
Byte 4: #02
Byte 5: #03
Byte 6: #04
Byte 7: #05
Byte 8: #06
Byte 9: #07
S
Byte 10: #08
Byte 11: #09
Byte 12: #10
Byte 13: #11
Byte 14: #12
Byte 15: #13
Byte 16: #14
Byte 17: #15
Byte 18: #16
Byte 19: #17
Byte 20: Check sum
= Byte2 + ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
Packing 2:
Byte 0: “ @” , 0x40;
Byte 1: 5
Byte 2: #18
Byte 3: #19
Byte 4: #20
Byte 5: #21
Byte 6: #22
Byte 7: #23
Byte 8: #24
Byte 9: #25
Byte 10: #26
Byte 11: #27
Byte 12: #28
Byte 13: #29
Byte 14: #30
Byte 15: #31
Byte 16: #32
Byte 17: #33
Byte 18: #34
Byte 19: #35
Byte 20: Check sum
= Byte2 + ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
Packing 3:
Byte 0: “ @” , 0x40;
Byte 1: 6
Byte 2: #36
Byte 3: #37
Byte 4: #38
Byte 5: #39
Byte 6: #40
Byte 7: #41
Byte 8: #42
Byte 9: #43
Byte 10: #44
Byte 11: #45
Byte 12: #46
Byte 13: #47
Byte 14: #48
Byte 15: #49
Byte 16: #50
Byte 17: #51
Byte 18: #52
Byte 19: #53
Byte 20:Check sum
= Byte2 + ..+Byte 19
Byte 21: 0X0D
Byte 22: 0X0A
Packing 4 & 5 will display only there is trouble code occurrence.
Packing 4:
Byte 0: “ @”
Byte 1: 7
Byte 2:a
Byte 3:b
Byte 4:c
Byte 5:a
Byte 6:b
Byte 7:c
Byte 8:a
Byte 9:b
Byte 10:c
Byte 11:a
Byte 12:b
Byte 13:c
Byte 14:a
Byte 15:b
Byte 16:c
Byte 17: Check sum
= Byte2 + ..+Byte 21
Byte 18: 0X0D
Byte 19: 0X0A
Packing 5:
Byte 0: “ @”
Byte 1: 8
Byte 2:a
Byte 3:b
Byte 4:c
Byte 5:a
Byte 6:b
Byte 7:c
Byte 8:a
Byte 9:b
Byte 10:c
Byte 11:a
Byte 12:b
Byte 13:c
Byte 14:a
Byte 15:b
Byte 16:c
Byte 17: Check sum
= Byte2 + ..+Byte 21
Byte 18: 0X0D
Byte 19: 0X0A
a — MID
b — SID or PID of a standard diagnostic code.
C — Diagnostic code character.
Bits 4-1: Failure mode identifier (FMI)
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
44
NOTE : The #00~#52 command respond that data are ASCII code.
VTC 100 User Manual
Page 58
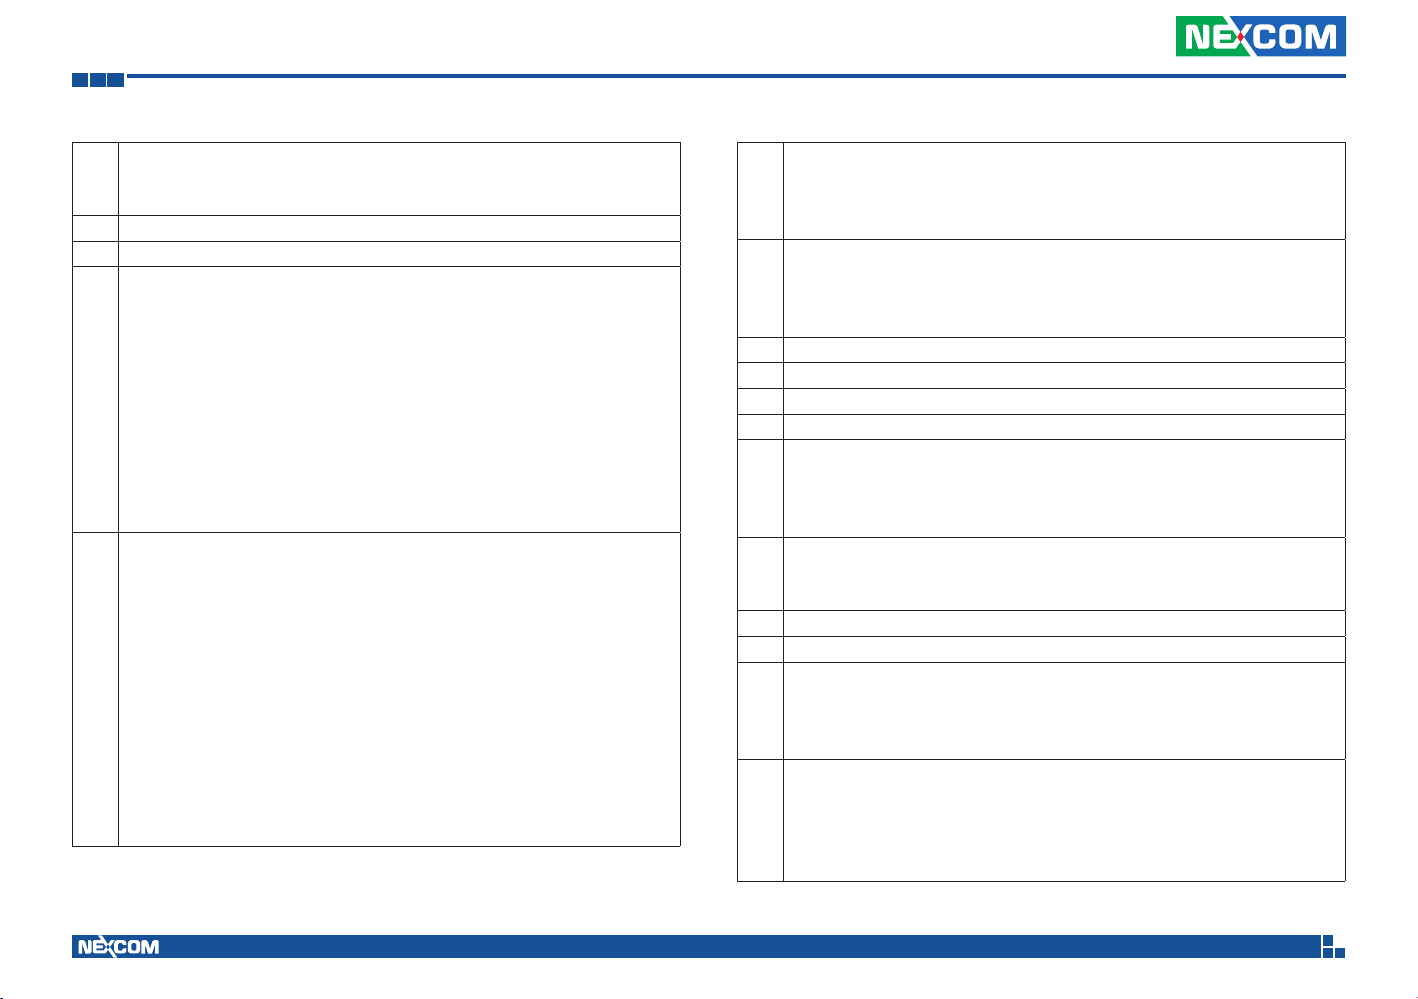
Appendix A: CAN Module Setup and Command
#00
Road Speed—Indicated vehicle velocity
|
Maximum Range: 0.0 to 205.2 km/h (0.0 to 127.5 mph)
#01
speed=(SHB*256+SLB)/256
#00 Speed Low Byte (SLB)
#01 Speed High Byte (SHB)
Cruise Control Status—State of the vehicle velocity control system
(active, not active), and system switch (on, off), for various system
operating modes.
Bit 8: cruise mode 1=active/0=not active
Bit 7: clutch switch 1=on/0=off
Bit 6: brake switch 1=on/0=off
#02
Bit 5: accel switch 1=on/0=off
Bit 4: resume switch 1=on/0=off
Bit 3: coast switch 1=on/0=off
Bit 2: set switch 1=on/0=off
Bit 1: cruise control switch 1=on/0=off
Brake Stroke Status—Identifies the current state of the vehicle
foundation brakes.
Bit 8-5: Axle number 1 to 16 (represented as 0 to 15)
Bit 4-2: Brake status/Stroke adjustment
000 = OK
001 = Out of adjustment
010 = Delay brake return
#03
011 = Brake pads worn
100 = Delayed brake application
101 = Reserved
110 = Error
111 = Not available
Bit 1: 1 = Left wheel, 0 = Right wheel
Percent Accelerator Pedal Position(PAPP)—Ratio of actual
accelerator pedal position to maximum pedal position.
#04
Maximum Range: 0.0 to 102.0%
PAPP= Data* 0.4
Total Fuel Used (Natural Gas)—Accumulated amount of fuel used
#05
during vehicle operation.
|
Maximum Range: 0.0 to 2 147 483 648 kg (0.0 to 4 724 464 025 lb)
#08
TFU=((ETF4*256*256*256)+(ETF3*256*256)+(ETF2*256)+ETF1)*0.473
#05 Engine Total Fuel used 0473 L / Bit gain , ETF1
#06 Engine Total Fuel used 0,473 L / Bit gain , ETF2
#07 Engine Total Fuel used 0,473 L / Bit gain , ETF3
#08 Engine Total Fuel used 0,473 L / Bit gain , ETF4
Fuel Level—Ratio of volume of fuel to the total volume of the
primary fuel storage container.
#09
Maximum Range: 0.0 to 127.5%
Fuel Level=FL * 0.5 %
#10
Engine Speed (RPM)—Rotational velocity of crankshaft.
|
Maximum Range: 0.0 to 16383.75 rpm
#11
RPM= (RH*256+ RL)* 0.25
#10 RPM Low byte, RL
#11 RPM High byte, RH
Engine Oil Pressure(EOP)—Gage pressure of oil in engine
lubrication system as provided by oil pump.
#12
Maximum Range: 0.0 to 879.0 kPa (0.0 to 127.5 lbf/in2)
EOP=data * 3.45 KPA
Throttle Position(TP)—The position of the valve used to regulate the
supply of a fluid, usually air or fuel/air mixture, to an engine. 0%
#13
represents no supply and 100% is full supply.
Maximum Range: 0.0 to 102.0%
TP= data * 0.4%
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
45
VTC 100 User Manual
Page 59
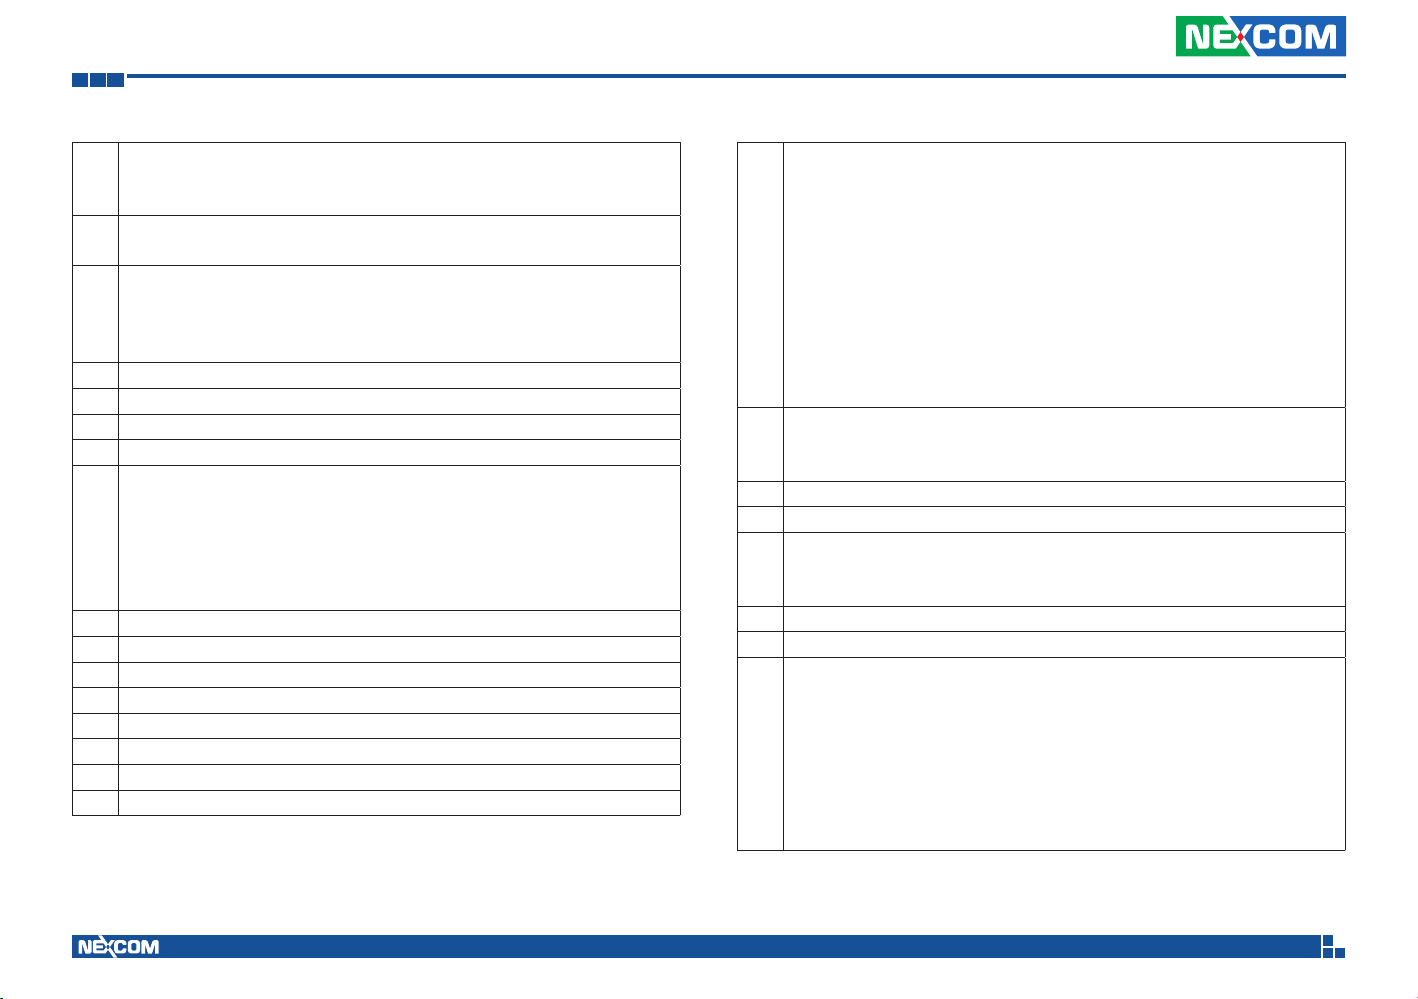
Appendix A: CAN Module Setup and Command
Cargo Weight—The force of gravity of freight carried.
#14
Maximum Range: 0.0 to 1 166 056.9 N (0.0 to 262 140.0 lbf)
(Low Byte),AWL
(High Byte), AWH
#15
Weight=(AWH*256+AWL)* 17.792 N
Total Engine Hours(TEH)—Accumulated time of operation of
engine.
#16
Maximum Range: 0.0 to 214 748 364.8 h
TEH=((EH4*256*256*256)+(EH3*256*256)+(EH2*256)+EH1)*0.05
#16 Engine total hours of Operation, EH1
#17 Engine total hours of Operation, EH2
#18 Engine total hours of Operation, EH3
#19 Engine total hours of Operation, EH4
#20
Vehicle Identification Number—Vehicle Identification Number (VIN)
|
as assigned by the vehicle manufacturer.
#27
Vehicle identification number, aabbccddeeffgghh
#85
“ATI” command can show max 20 character VIN
|
#96
#20 aa
#21 bb
#22 cc
#23 dd
#24 ee
#25 ff
#26 gg
#27 hh
PTO Engagement Control Status
PTO output status:
Bits 8-5: Reserved—all bits set to 1
Bits 4-3: PTO #2 engagement actuator status
Bits 2-1: PTO #1 engagement actuator status
NOTE—Each status will be described using the following
#28
nomenclature:
00 Off/Not active
01 On/Active
10 Error condition
11 Not available
#29
Average Fuel Economy
|
AFE=((AFE2*256)+AFE1) *1.660 72 x 10-3 km/L
#30
#29 AFE1
#30 AFE2
#31
Mass Air Flow—Mass air flow measured at the fresh air intake
|
MAF=((MAF2*256)+MF1)* 0.125 kg/min
#32
#31 MAF1
#32 MAF2
Total Vehicle Distance(TVD)—Accumulated distance travelled by
vehicle during its operation.
Maximum Range: 0.0 to 691489743 km (0.0 to 429 496 729.5 mi)
#33
Bit Resolution: 0.161 km (0.1 mi)
|
TVD=((D4*256*256*256)+(D3*256*256)+(D2*256)+D1)*0.161 (KM)
#36
If vehicle dose not provide TVD, AT1708 replace the information
with the calculated distance, deviation is 0.5%, The first time
connection AT1708 please command ATR to clear distance memory.
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
46
VTC 100 User Manual
Page 60
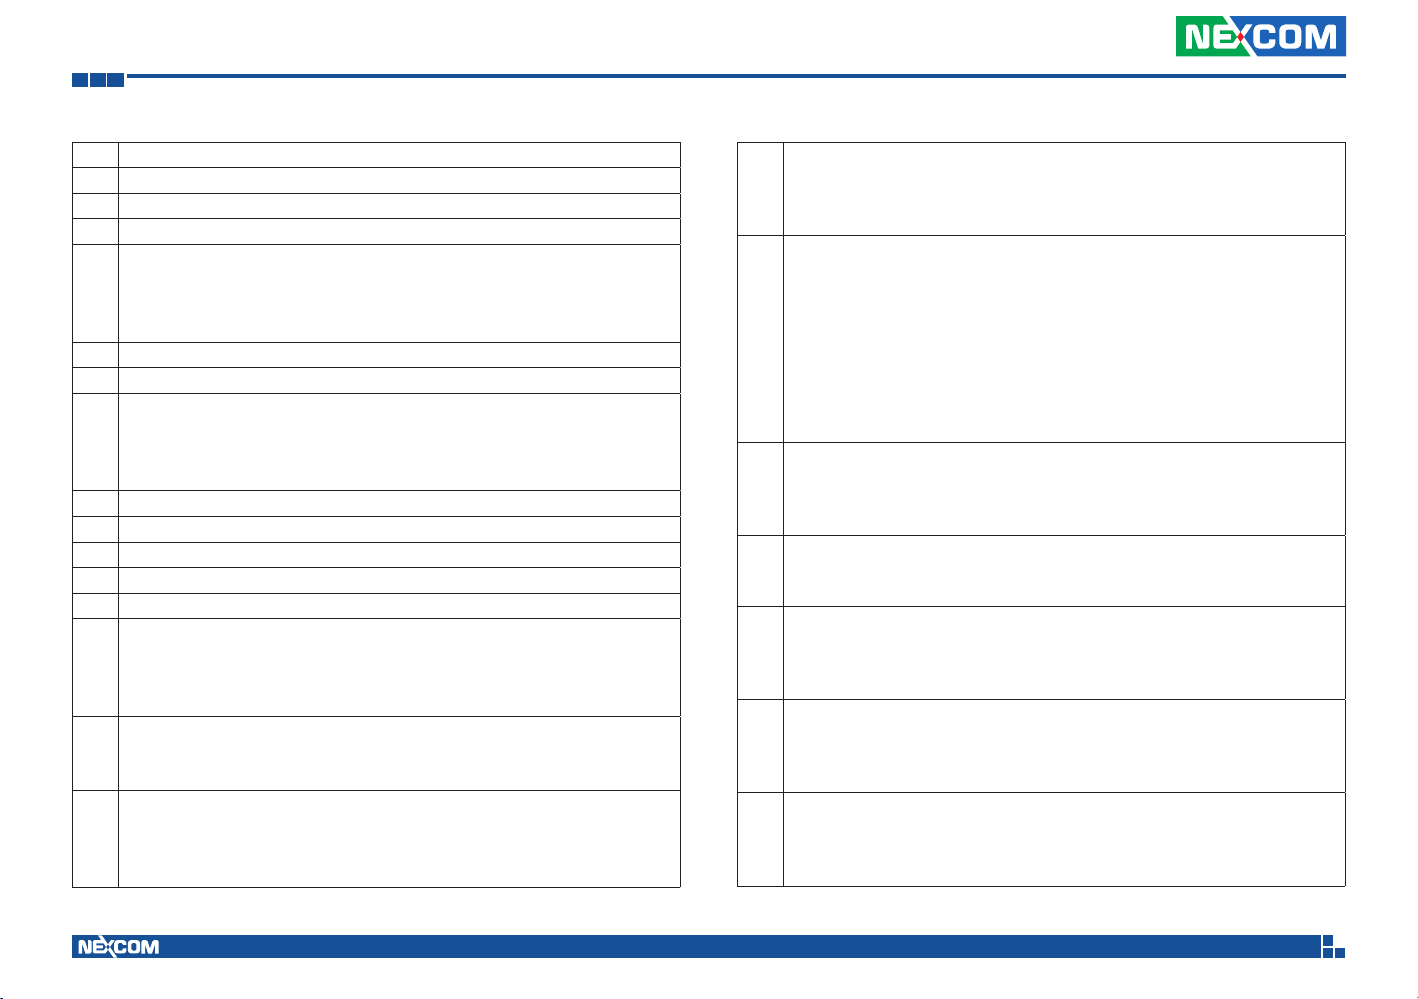
Appendix A: CAN Module Setup and Command
#33 D1
#34 D2
#35 D3
#36 D4
Fuel Rate (Instantaneous)—Amount of fuel consumed by engine per
#37
unit of time.
|
Maximum Range: 0.0 to 1.076 65 L/s
#38
FR=(V2*256+V1) * 16.428 x 106 L/s
#37 V1
#38 V2
Total Vehicle Hours(TVH)—Accumulated time of operation of
#39
vehicle.
|
Maximum Range: 0.0 to 214 748 364.8 h
#40
TVH=((H4*256*256*256)+(H3*256*256)+(H2*256)+H1)*0.05 (H)
#39 H1
#40 H2
#41 H3
#42 H4
#43 Reserved
Percent Engine Load(PEL)—Ratio of current output torque to
maximum torque available at the current engine speed.
#44
Maximum Range: 0.0 to 127.5%
PEL=data * 0.5%
Engine Coolant Temperature(ECT) ,
#45
Maximum Range: 0.0 to 255.0 °F
ECT= data °F
Boost Pressure (BP)—Gage pressure of air measured downstream
on the compressor discharge side of the turbocharger.
#46
Maximum Range: 0.0 to 219.8 kPa (0.0 to 31.875 lbf/in2)
PB=data * 0.862 (KPA)
Intake Manifold Temperature (IMT)—Temperature of precombustion
air found in intake manifold of engine air supply system.
#47
Maximum Range: 0.0 to 255.0 °F
IMT=data °F
ABS Control Status
Bits 8-7: ABS off-road function switch
Bits 6-5: ABS retarder control
Bits 4-3: ABS brake control
Bits 2-1: ABS warning lamp
#48
00 Off/Not active
01 On/Active
10 Error condition
11 Not available
Parking Brake Switch Status—Identifies the state (active/inactive) of
the parking brake switch.
#49
Bit 8: 1=active/0=inactive
Bits 7-1: Undefined
Brake Application Pressure (BAP)
#50
Maximum Range: 0.0 to 1055 kPa (0.0 to 153.0 lbf/in2)
BAP=data *4.14 kPa
Brake Primary Pressure (BPP)—Gage pressure of air in the primary,
or supply side, of the air brake system.
#51
Maximum Range: 0.0 to 1055 kPa (0.0 to 153.0 lbf/in2)
BPP=data* 4.14 (KPA)
Brake Secondary Pressure—Gage pressure of air in the secondary,
or service side, of the air brake system.
#52
Maximum Range: 0.0 to 1055 kPa (0.0 to 153.0 lbf/in2)
BPP=data* 4.14 (KPA)
Road Speed Limit Status :State (active or not active) of the system
used to limit maximum vehicle velocity.
#53
Bit 8: 1=active/0=not active
Bits 7-1: Undefined
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
47
VTC 100 User Manual
Page 61
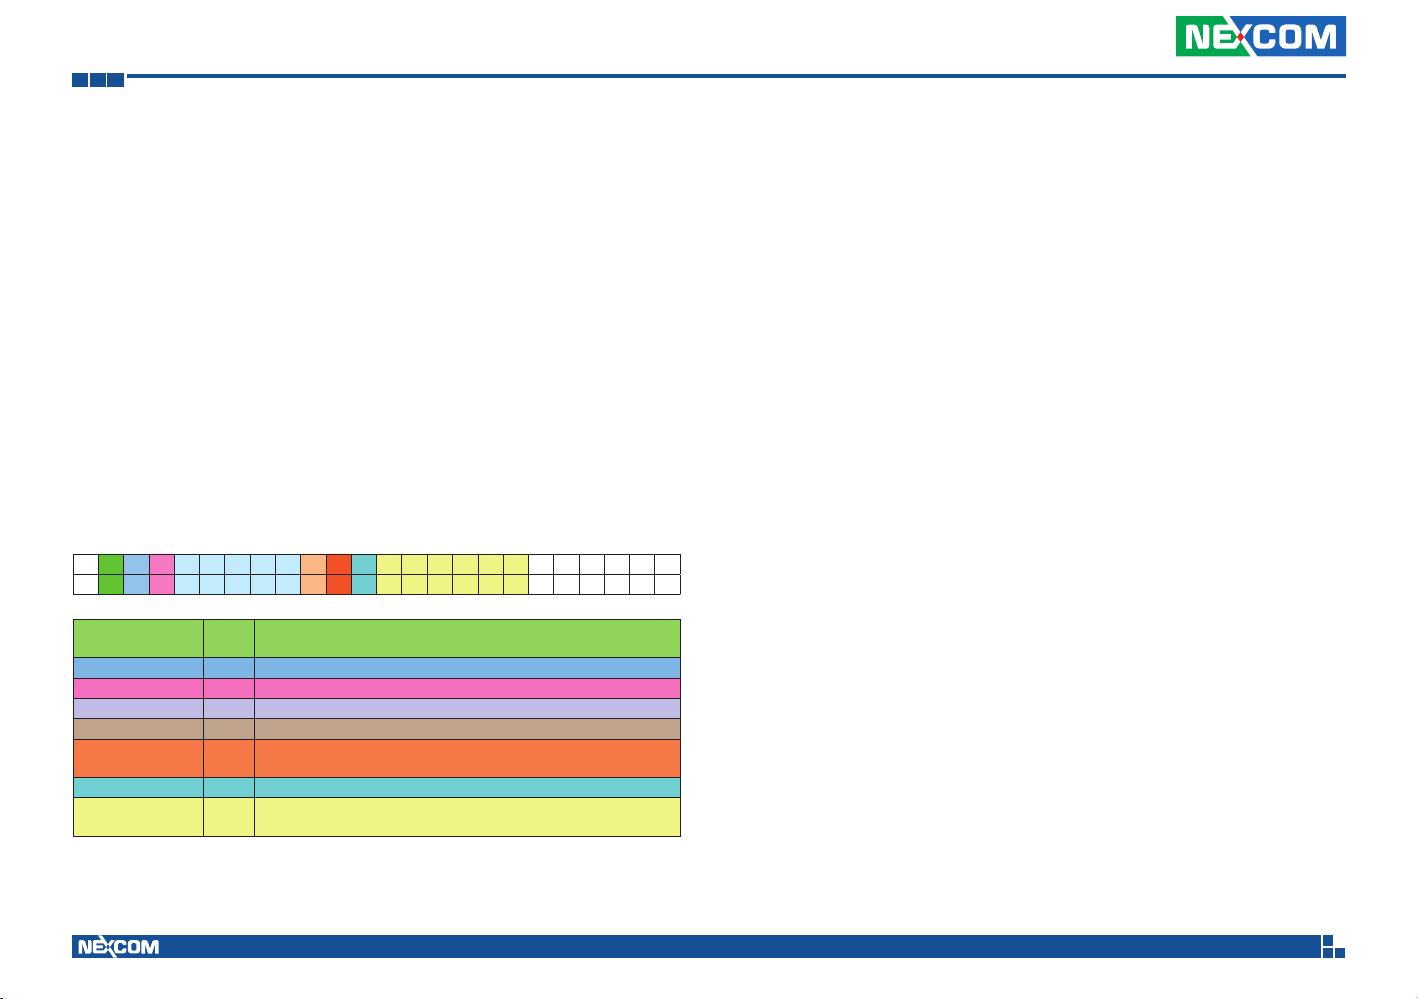
Appendix A: CAN Module Setup and Command
J1708 Command Example
1.) >AT#h,
Response: “Data1” “Data2” “H0D” “H3E” by ASCII CODE.
EX1:
AT#1, to get vehicle speed, if speed is 255,
Display,
FF
>
(H46,H46, H0D,H3E).
2.) Trouble code :
40 37 80 8 CA 80 A AA 80 B AA 80 C AA 80 1 AA FC D A
Trouble code :
MID 128( H80)
PID 8(H8)
Diagnostic code character ( CA), FMI= A , bit4~bit1
4.) ATI : request vehicle ID,
2A 31 47 31 4A 46 32 37 57 37 47 4A 31 37 38 32 32 37 0 0 0 27 0D 0A
1 G 1 G F 2 7 W 8 G J 1 7 8 2 2 7 CS
Country Manufactured 1
Manufacturer G
Vehicle Type 1
Vehicle Features JF27W
Accuracy Check Digit 8
Model Year G
Production Plant J
Sequential Number 178227
Copyright © 2013 NEXCOM International Co., Ltd. All Rights Reserved.
U.S.A.(1 or 4), Canada (2), Mexico (3), Japan (J), Korea (K), England (S),
Germany (W), Italy (Z)
1988 (J), 1989 (K), 1990 (L), 1991 (M), 1992 (N), 1993 (P), 1994 (R), 1995 (S),
1996 (T), 199 7(V), 1998 (W), 1999 (X), 2000 (Y), 2001(1), 2002 (2), 2003 (3)…..
The sequence of the vehicle for production as it rolled of the manufacturers
assembly line.
48
VTC 100 User Manual
 Loading...