

Page 1
LEADERS IN CAMERA ROBOTICS
CRANES AND RIGS | BROADCAST | HEADS & DSLR | PRODUCT PHOTOGRAPHY | RENTALS
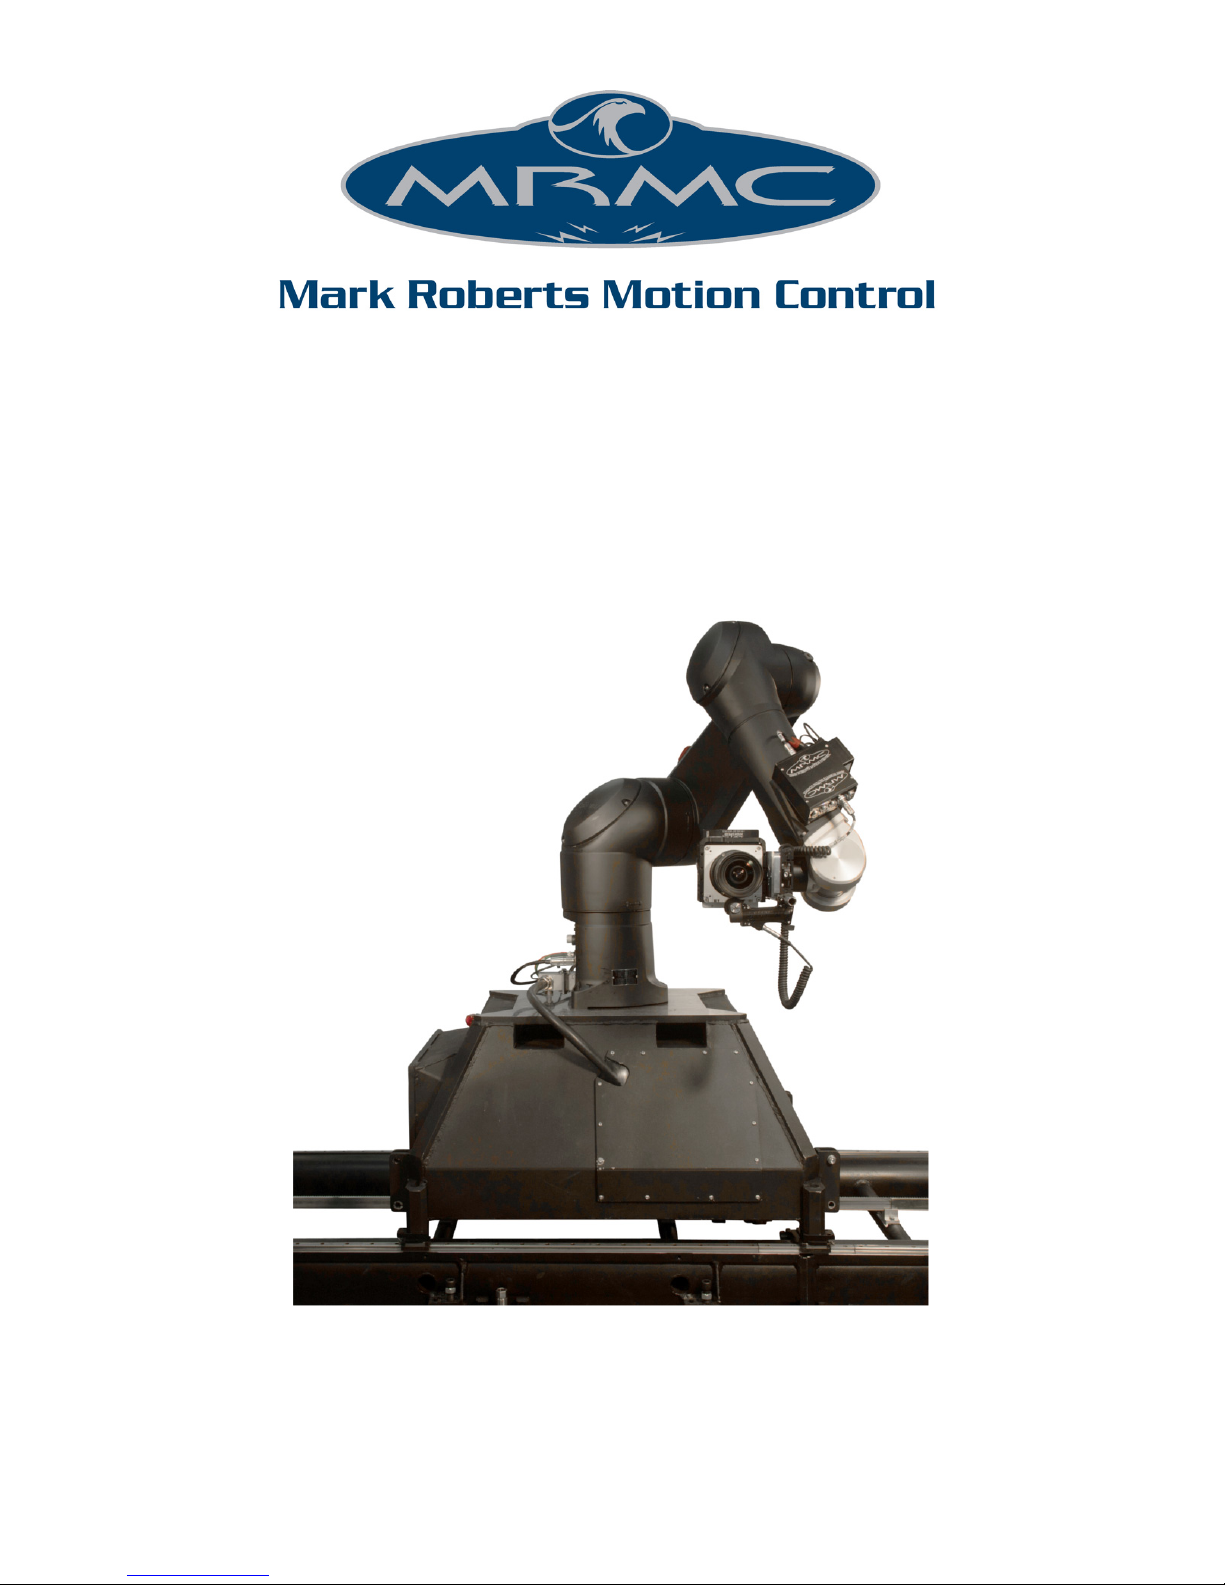
Bolt Junior
COMPACT LIGHTWEIGHT HIGH SPEED ROBOT
Quick Start Guide
Product Code: MRMC-1558-00
Part number: MRMC-1567-00
Page 2
ii
Bolt Junior Quick Start Guide
Product Code: MRMC-1558-00
Part number: MRMC-1567-00
© 2018 Mark Roberts Motion Control Ltd. All rights reserved.
No part of this publication may be reproduced, transmitted, or translated
by any means — graphical, electronic, or mechanical — including
photocopying, recording, taping, or storage in an information retrieval
system, without the express written permission of Mark Roberts Motion
Control.
Although every care has been taken to ensure that the information in this
document is accurate and up to date, Mark Roberts Motion Control
continuously strives to improve their products and may make changes to
the hardware, firmware, and software described in this document. Mark
Roberts Motion Control therefore cannot be held responsible for any
error or omission in this document.
All product names mentioned herein are the trademarks or registered
trademarks of their respective owners.
Contact information
Mark Roberts Motion Control Ltd.
Unit 3, South East Studios
Blindley Heath
Surrey
RH7 6JP
United Kingdom
Telephone: +44 (0) 1342 838000
E-mail: [email protected] (sales and general enquiries)
[email protected] (customer support)
Web: www.mrmoco.com
www.mrmocorentals.com
Page 3
Bolt Junior Quick Start Guide
iii
Bolt Junior Quick Start GuideBolt JuniorQuick Start Guide
Contents
Chapter 1 Quick Start..................................................................... 1
Overview .................................................................................1
Safety procedures for using industrial robots,
including high speed track....................................................2
Assessing a site..............................................................3
Installation safety.......................................................... 3
Software setup ...............................................................6
Operational safety.........................................................6
Connecting the cables ...........................................................8
Bolt Junior arm connectors for Ulti-box and camera .....11
Starting up the Bolt Junior system.....................................12
Bolt Junior start-up summary...................................16
Shutting down the Bolt Junior system...............................17
Bolt Junior shut-down summary..............................18
Moving the Bolt Junior arm by hand.................................18
Appendix 1 Troubleshooting...........................................................22
Typical symptoms, causes, and actions .............................22
Appendix 2 Bolt Junior panels........................................................ 24
Bolt Junior Base panel connector summary.....................24
Bolt Junior arm panels connector summary ....................26
Ulti-box connector summary.............................................28
Ulti-box connector pin-out information ..........................30
Servo motor connector ..............................................30
Program serial connector ..........................................30
Power connector .........................................................31
Camera Accessory connector....................................31
Data In connector.......................................................32
Appendix 3 Specifications............................................................... 34
Rig Weights ........................................................34
Rig Performance................................................34
Operating Envelope ..........................................34
Page 4
Bolt Junior Quick Start Guide
iv
Page 5
Bolt Junior Quick Start Guide
1
Bolt Junior Quick Start GuideBolt JuniorQuick Start Guide
Chapter 1 Quick Start
Overview
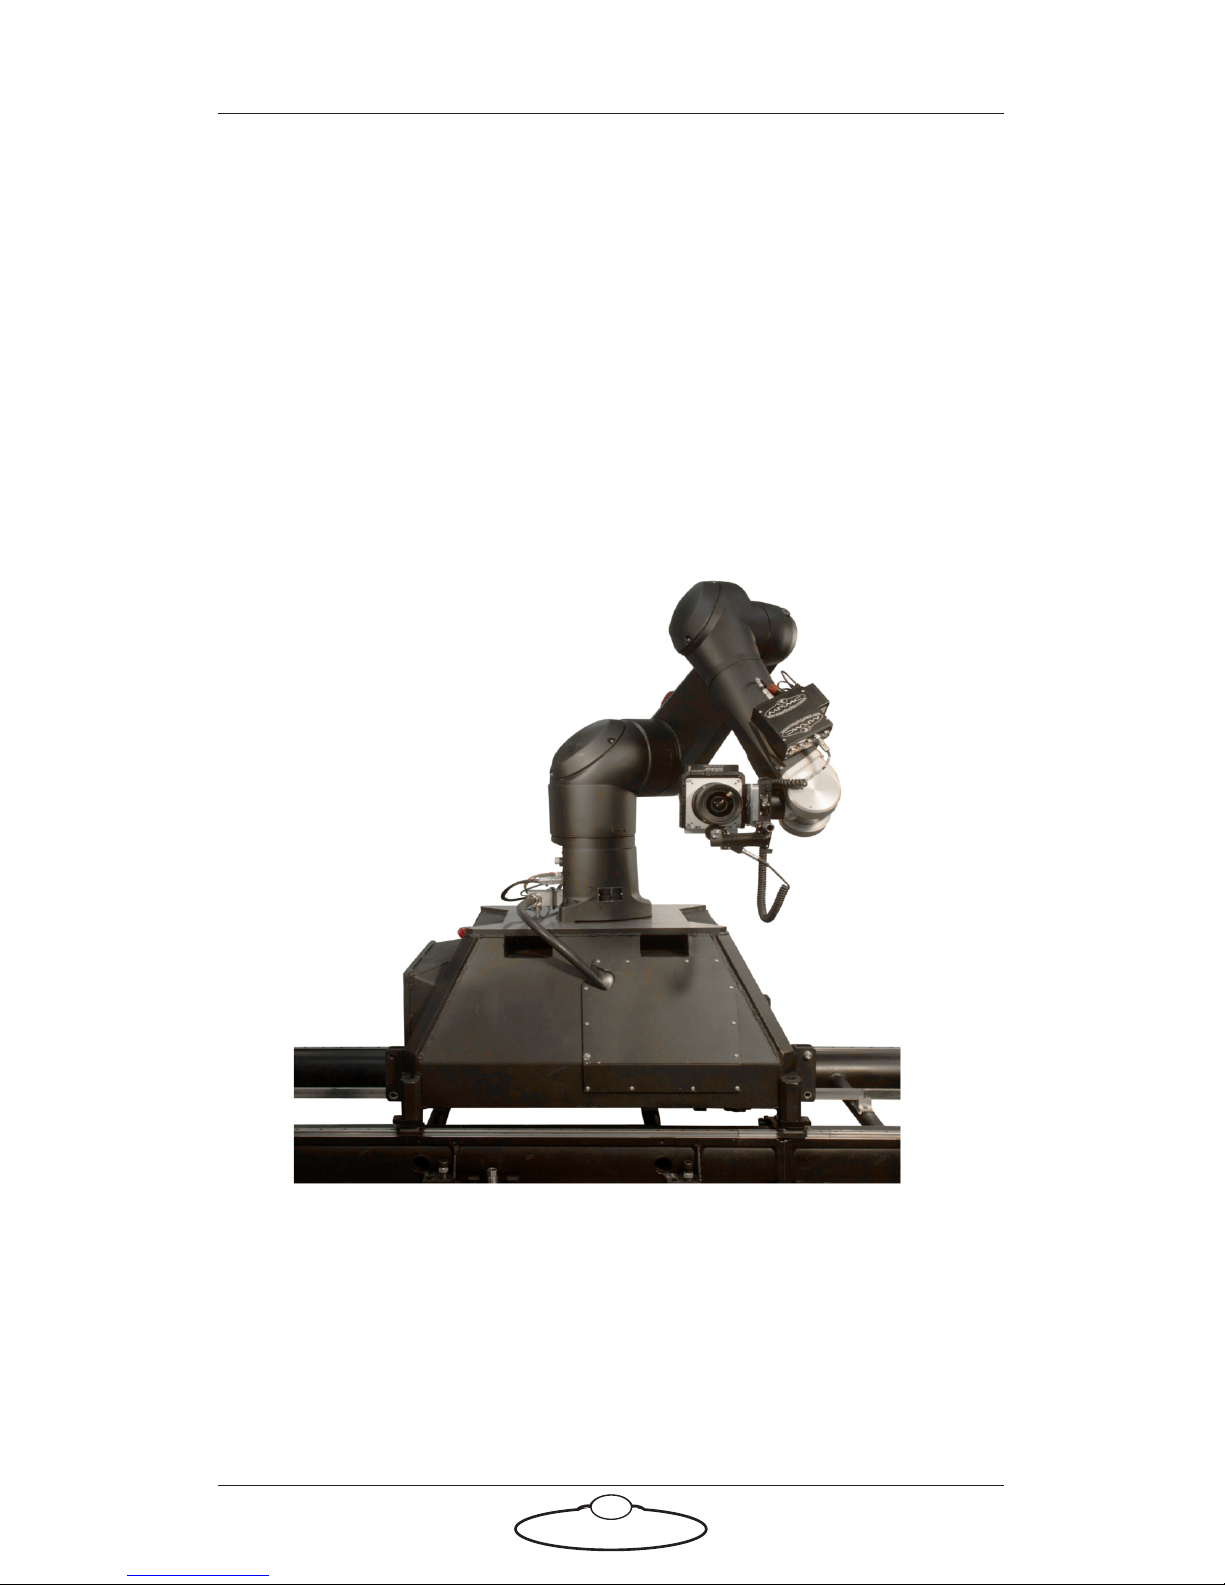
Thank you for using the Bolt Junior Cinebot from Mark Roberts Motion
Control (MRMC). Bolt Junior is designed for reliable day-in, day-out use
in professional studio and Outside Broadcast environments. It has a
small, lightweight robotic arm which can be used either as camera rig or
model mover. It has a base designed for moving along Precision Track,
which can be bolted to the ground and can also be held down with
weights at temporary locations. It has removable trolley wheels for
moving between sets.
Page 6
Bolt Junior Quick Start Guide
2
Safety procedures for using industrial robots,
including high speed track
Note that the words Robot and Rig are completely interchangeable and
identical in meaning, for the purposes of this document.
Motion Control rigs are potentially dangerous. It is important that you
and everyone else on the set understand the safety notes on the following
pages in order to stay safe.
You should use this document in addition to the normal Safety Manual
instructions that are applicable to all motion control rigs, such as Milos.
This section emphasises the safety concerns that are especially important
around high-speed, high-acceleration, industrial-grade robots which can
cause severe injuries, such as Bolt Junior.
Unlike traditional motion control equipment, Bolt Junior can
get to maximum speed in the blink of an eye - too fast for
someone to be able to quickly move out of the way.
You need to take extra steps during installation and use due to
the additional risks involved in using track. See the separate
Precision Track Quick Start Guide for information on laying the
track, securing it to the floor, and mounting Bolt Junior onto it.
The notes given below for track users are marked with this
symbol: .
It is ultimately the operator of the rig who is responsible for
the safe use of the equipment so never bypass any of the safety
points listed here.
No one other than a highly trained operator should use the
robot, no matter how simple it looks or is.
This document is for the use of robots for carrying cameras or
props, not people. Additional safety steps should be taken prior
to using a rig to carry people.
Page 7
Bolt Junior Quick Start Guide
3
Assessing a site
Before setting up Bolt Junior you need to assess the site, paying particular
attention to the following points:
Is the ground or floor firm enough and level enough? You
might have to use boards or bricks to create a level surface. The
surface needs to be strong enough to take the weight of Bolt
Junior itself (294 kg) plus the weight of the track (95 kg per
section).
Does the site have access? You need to make sure you can
either push Bolt Junior into position on its wheels or carry it
there using a pallet truck or forklift.
Does the site have a power source with sufficient capacity for
the robot and the correct mains voltage?
– Bolt Junior requires a 400 Volt, three-phase power
supply (five-wire including Neutral and Ground), and
can not be configured to run on less.
– The computer stack that controls Bolt Junior (that is, the
desktop computer and the power supply brick for the
RT-14 interface box) are auto-switching and can run on
120-240 Volts AC.
Does the site have unusual environmental attributes that
require specialised protection from extreme temperatures,
humidity, rain, or dust?
Installation safety
Due to the large mass of the rigs and the accelerations they
achieve it is important that they are securely mounted, with the
recommended plates and bolts to a secure and concrete floor.
When using track, ensure that it is properly bolted to the floor.
If bolting the track is not possible, use 100kg of counter
weights on each corner of the track.
Make sure there is plenty of clearance around the length of the
track for the trailing cables of the rig to slide along the floor.
Ensure that they are not mounted in such a way so that they
can catch on the track or robot as it moves along the full
length.
Page 8
Bolt Junior Quick Start Guide
4
Ensure the floor can support the load and the stresses (see
above).
Ensure the power supply is properly earthed (grounded) and of
the correct voltage (see above).
If the rig is mounted to something other than the floor then
the mount should be heavy and strong enough to take the
forces and not move or fall over during sudden starts and
stops. Use the recommended minimum thickness steel plates.
Check with MRMC if you are unsure of the exact requirements
for your robot.
Check that all cables are securely fixed and are not going to
catch during motion.
Ensure the camera, lens, focus motor, accessories, power
supplies/batteries, etc. are all very securely mounted and will
not come off during sudden motions, to become lethal
missiles.
Ensure all safety accessories are securely attached and in
working order, including emergency stops, safety sensors, etc.
Clearly mark the area around the robot in which no persons
are allowed to enter. As a bare minimum, use brightly marked
tape on the floor, outside the reach of the robot, to indicate the
“No Go Zone”. Ideally, use physical safety barriers, and light
guards/curtains.
Keep stands, lights and accessories out of the No Go Zone, if
possible. If not possible then try to take as much care with their
positioning and the motion of the rig, as if they were a person.
Remember a light, accidentally hit at high speed by the robot,
can be just as dangerous to someone standing outside the No
Go Zone as the robot is to someone standing in the zone.
Where physical safety barriers are impractical, light guards
should be used or similar alternatives such as laser scanners, to
stop anyone entering the No Go Zone during motion.
Ideally have the robot surrounded on all four sides by a safety
barrier, but where that is not practical, ensure that the
maximum number of sides feasible are closed off, and that any
person having to stand within reach of the robot is located as
far away as possible for the shot.
Page 9
Bolt Junior Quick Start Guide
5
Never let anyone cross the robot’s track when the track motor
is powered up. In fact, it is a good idea to get into the routine of
walking around the track instead of over it so that you don’t
cross the track out of habit when the track motor is powered
up.
Page 10
Bolt Junior Quick Start Guide
6
Software setup
Always ensure you have the right configuration for the robot
you are using, such as maximum axis speeds and accelerations.
Prior to running moves, enter in and keep to a minimum all
software axis and Cartesian limits. For example if the main axis
only needs to travel +/-40 degrees then reduce the limit to +/
-40 degrees even though it could do +/-180 degrees. This keeps
the likelihood of operator or software errors to a minimum.
Also check the Cartesian speed and acceleration limits are set
to reasonable values.
Operational safety
Do not use around flammable gas. All electrical equipment can
generate sparks that can ignite flammable gas.
Keep the equipment dry. The system has not been made
weatherproof. Do not use with wet hands.
Always run moves only when standing within easy reach of the
emergency stop.
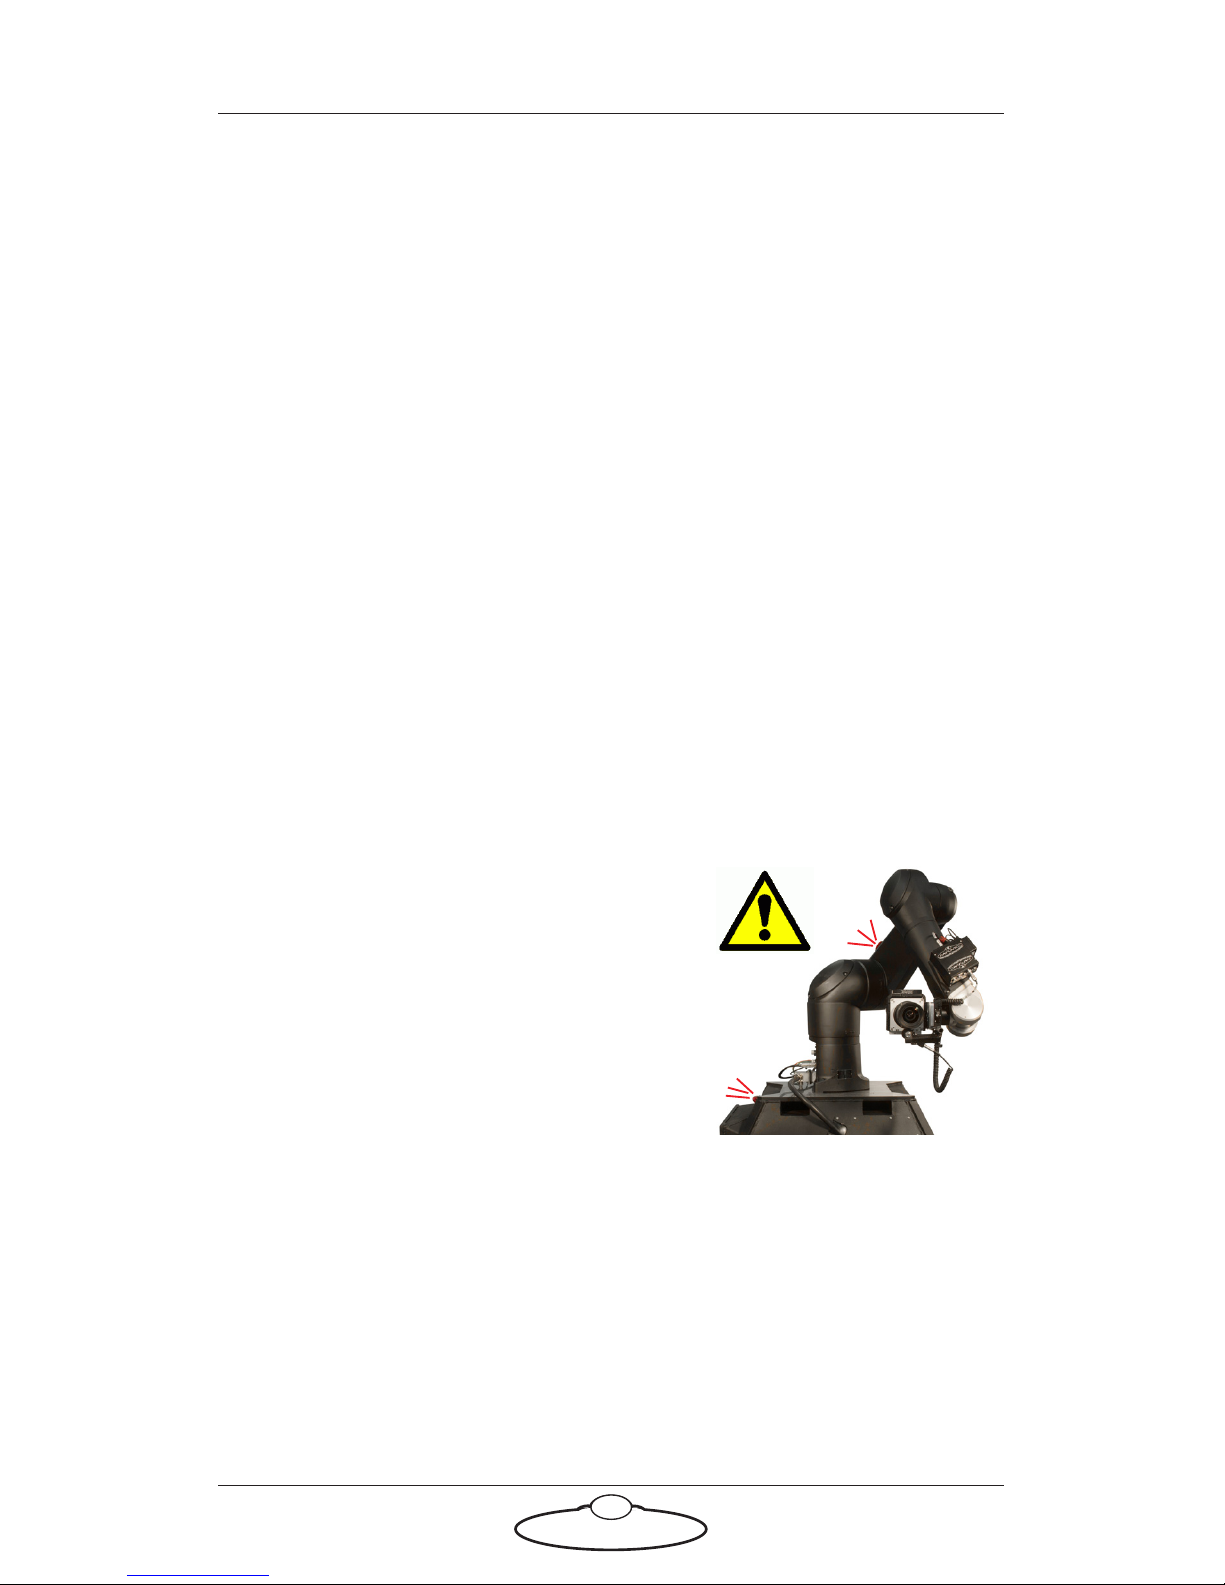
Always tell the production
company and the crew to keep
away from the robot and not
approach it when any of its red
lights are on which indicates it is
powered up. Have them sign the
appropriate safety documents
and disclaimers to ensure they
understand this and are
indemnifying MRMC if
anything happens.
Always loudly and clearly indicate to others when the rig is
about to move. Shout “Rig Moving!” if no other means exists.
When using track motion always have someone keep an eye on
the trailing rig cables to ensure they don’t get caught on
anything or anyone.
Always ensure the rig is disabled when someone has to enter
the No Go Zone.
Page 11
Bolt Junior Quick Start Guide
7
Always run any move or adjusted move slowly at first to check
the motion. Even if you have checked the move previously, if
you make a minor change to it then you need to recheck it.
Keep the software in “slow mode” unless the move has been
tested and is now specifically doing a high speed pass.
In the event that a person or Actor has to be within the no-go
zone during a move (hand model etc.) ensure that they fully
briefed on the safety requirements and that they know not to
change their position or do anything other than the rehearsed
moves without fully warning the operator. Any such person is
to have a clear escape route to allow them to move safely away
from the robot.
During use, repeatedly check the rig mounting points, cables,
camera mount, accessories etc. to ensure nothing has, or is,
working its way loose.
Never bypass any safety hardware or software.
Page 12
Bolt Junior Quick Start Guide
8
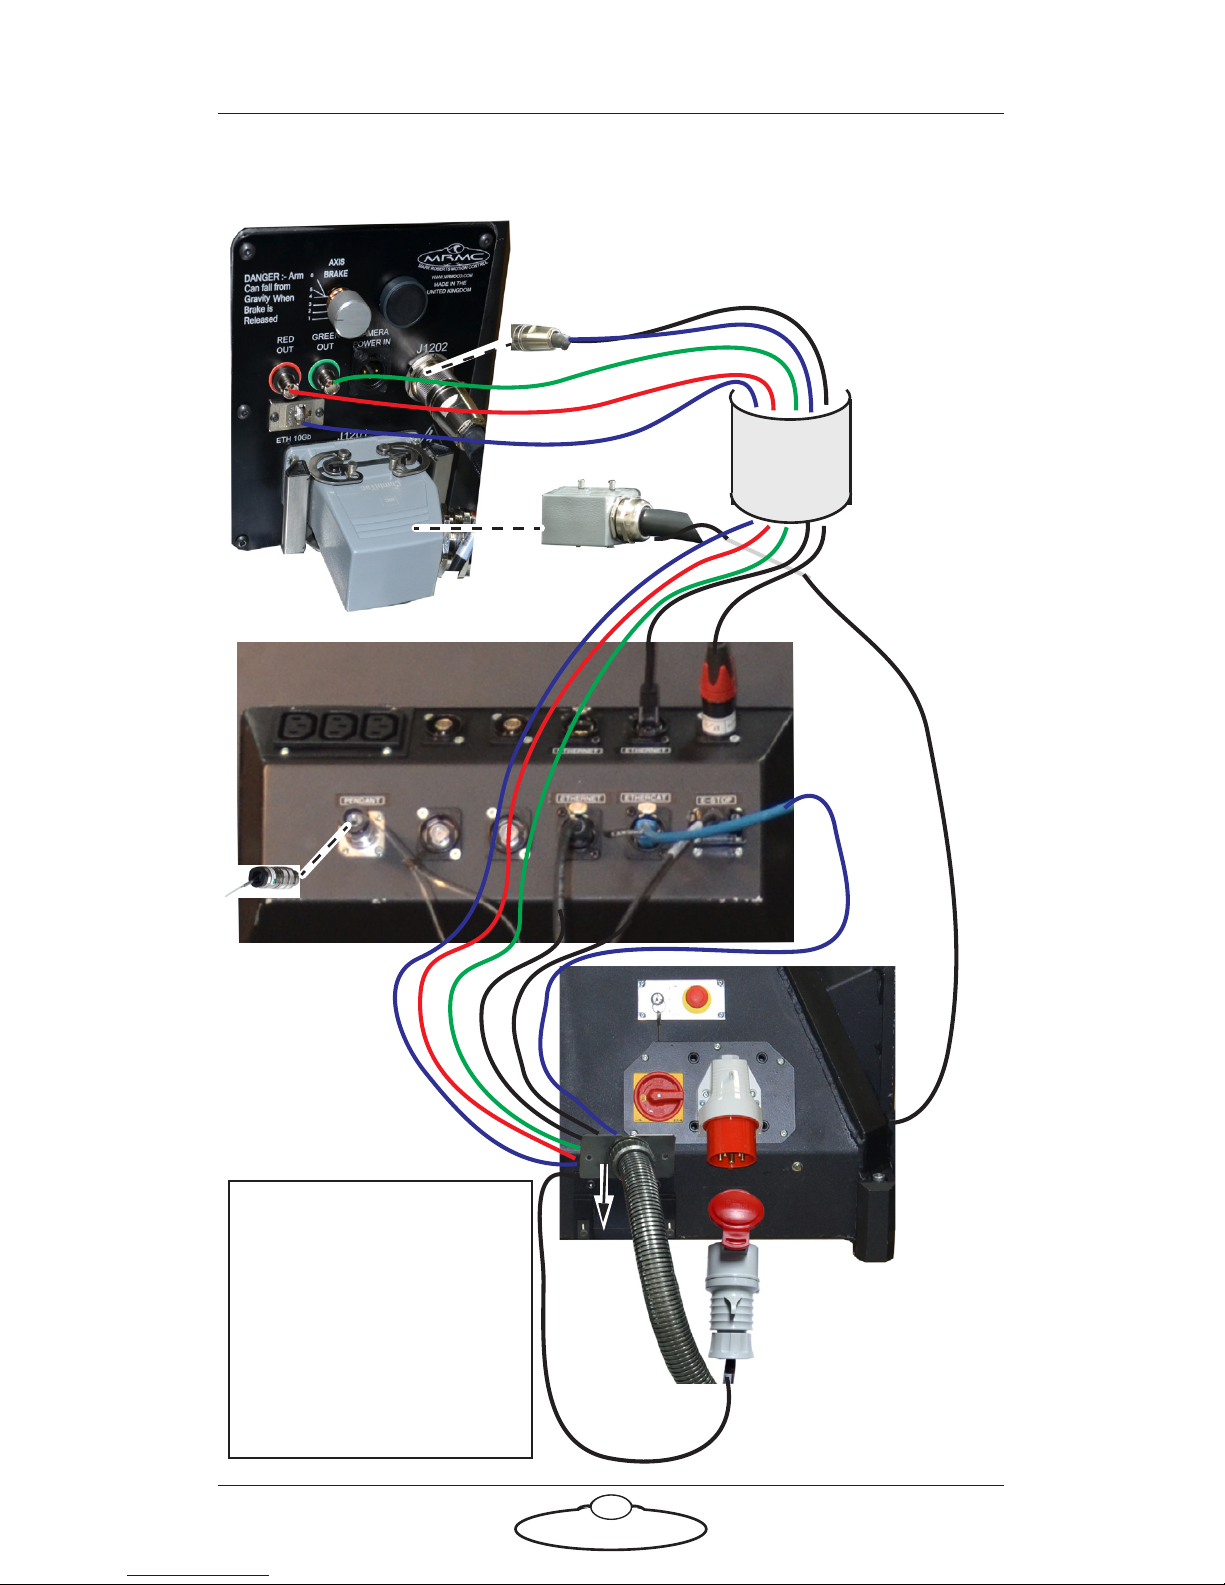
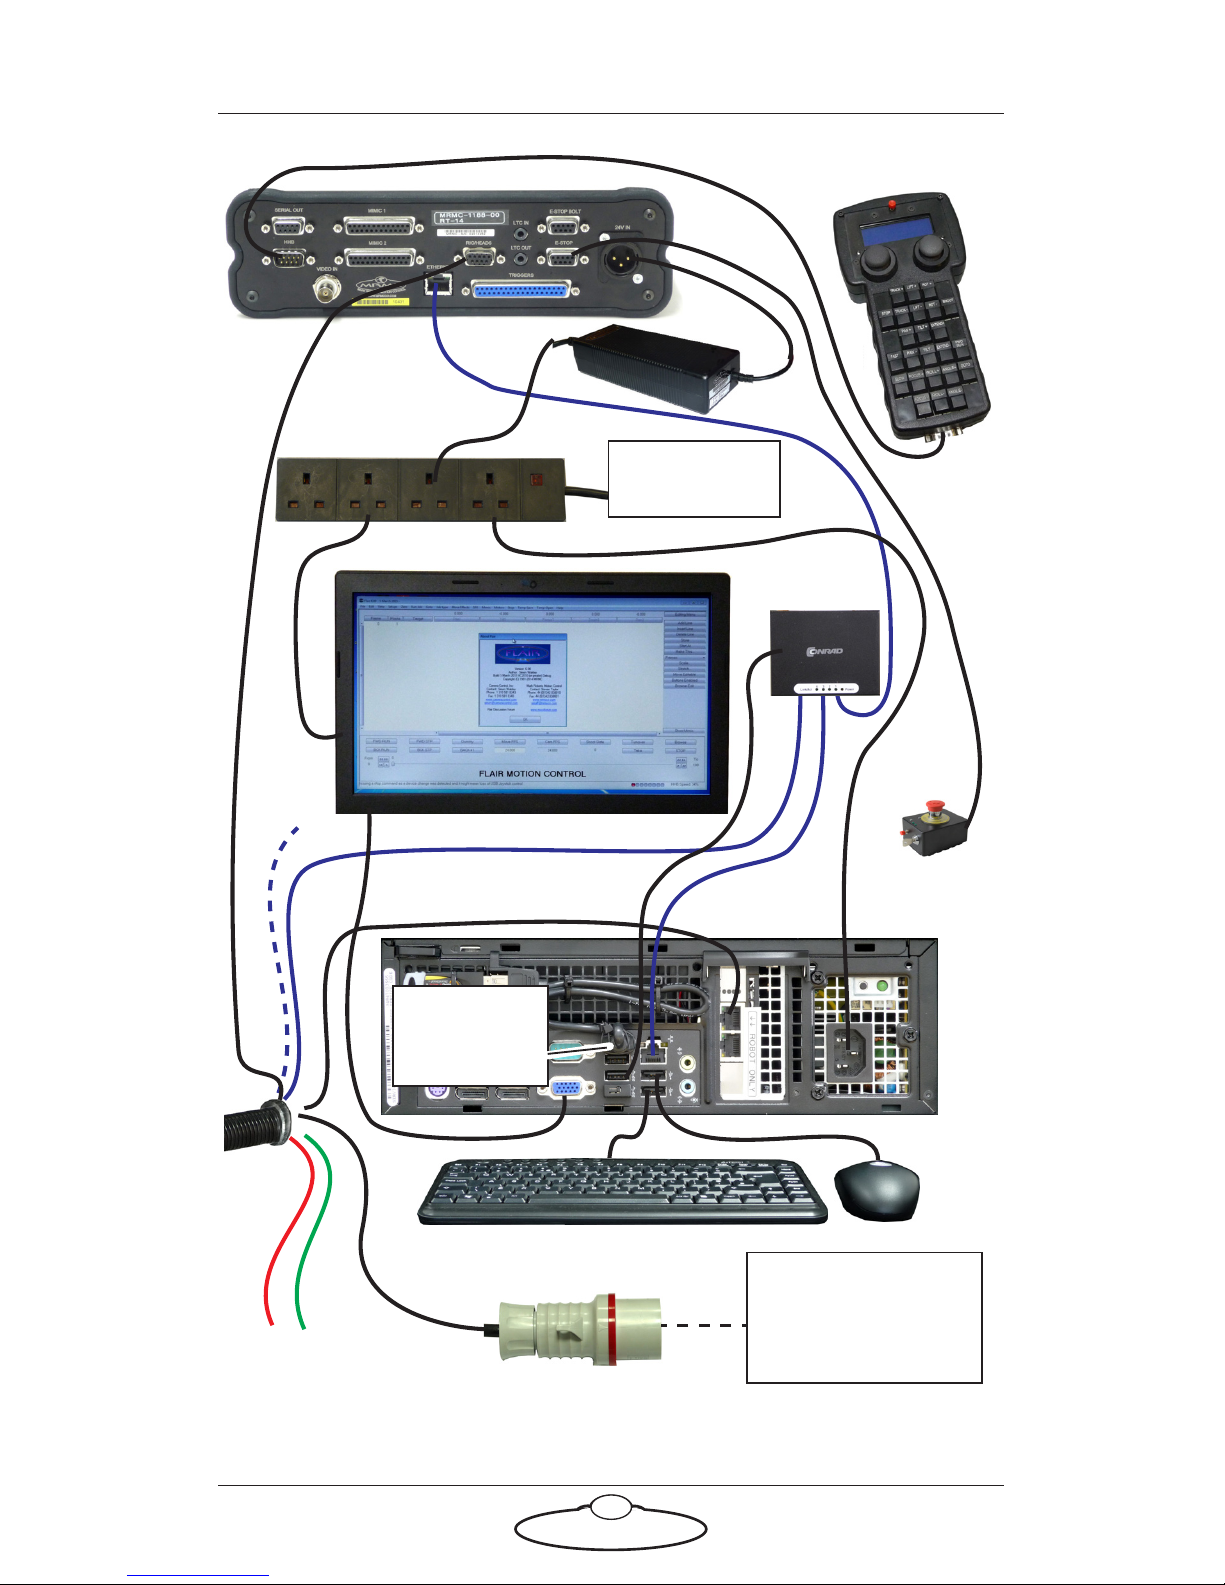
Connecting the cables
Cable
wrap
VIDEO 1
J1201
48V OUT
E-STOP
E
THERNE
T
VIDEO 2
ETH*
415 Volt
*These Ethernet (ETH)
ports are for network
connection to the track
motor controller and to the
Ulti-box for LCMs via the
Staubli arm. ETHERCAT
goes to the Stäubli CS8 in
the base only, which
controls the arm.
TEACH
PENDANT
for C
amer
a
POWER
E
THER
C
A
T
J1202
E
THERNET 10GB
ETH*
Page 13
Bolt Junior Quick Start Guide
9
ETHERCAT
E-STOP
Ethernet
Power Supply:
415 Volt, 3-phase,
5-wire including
Neutral and Ground
VIDEO SIGNALS
Power Supply:
120-240 Volts
hub
5V
INtime
dongle cable
in USB port
RT-14
Hand Held Box
Ethernet for Camera
ETHERNET
E-ST
OP
POWER
ETHERNET
24V IN
EX-011 c
able
Page 14
Bolt Junior Quick Start Guide
10
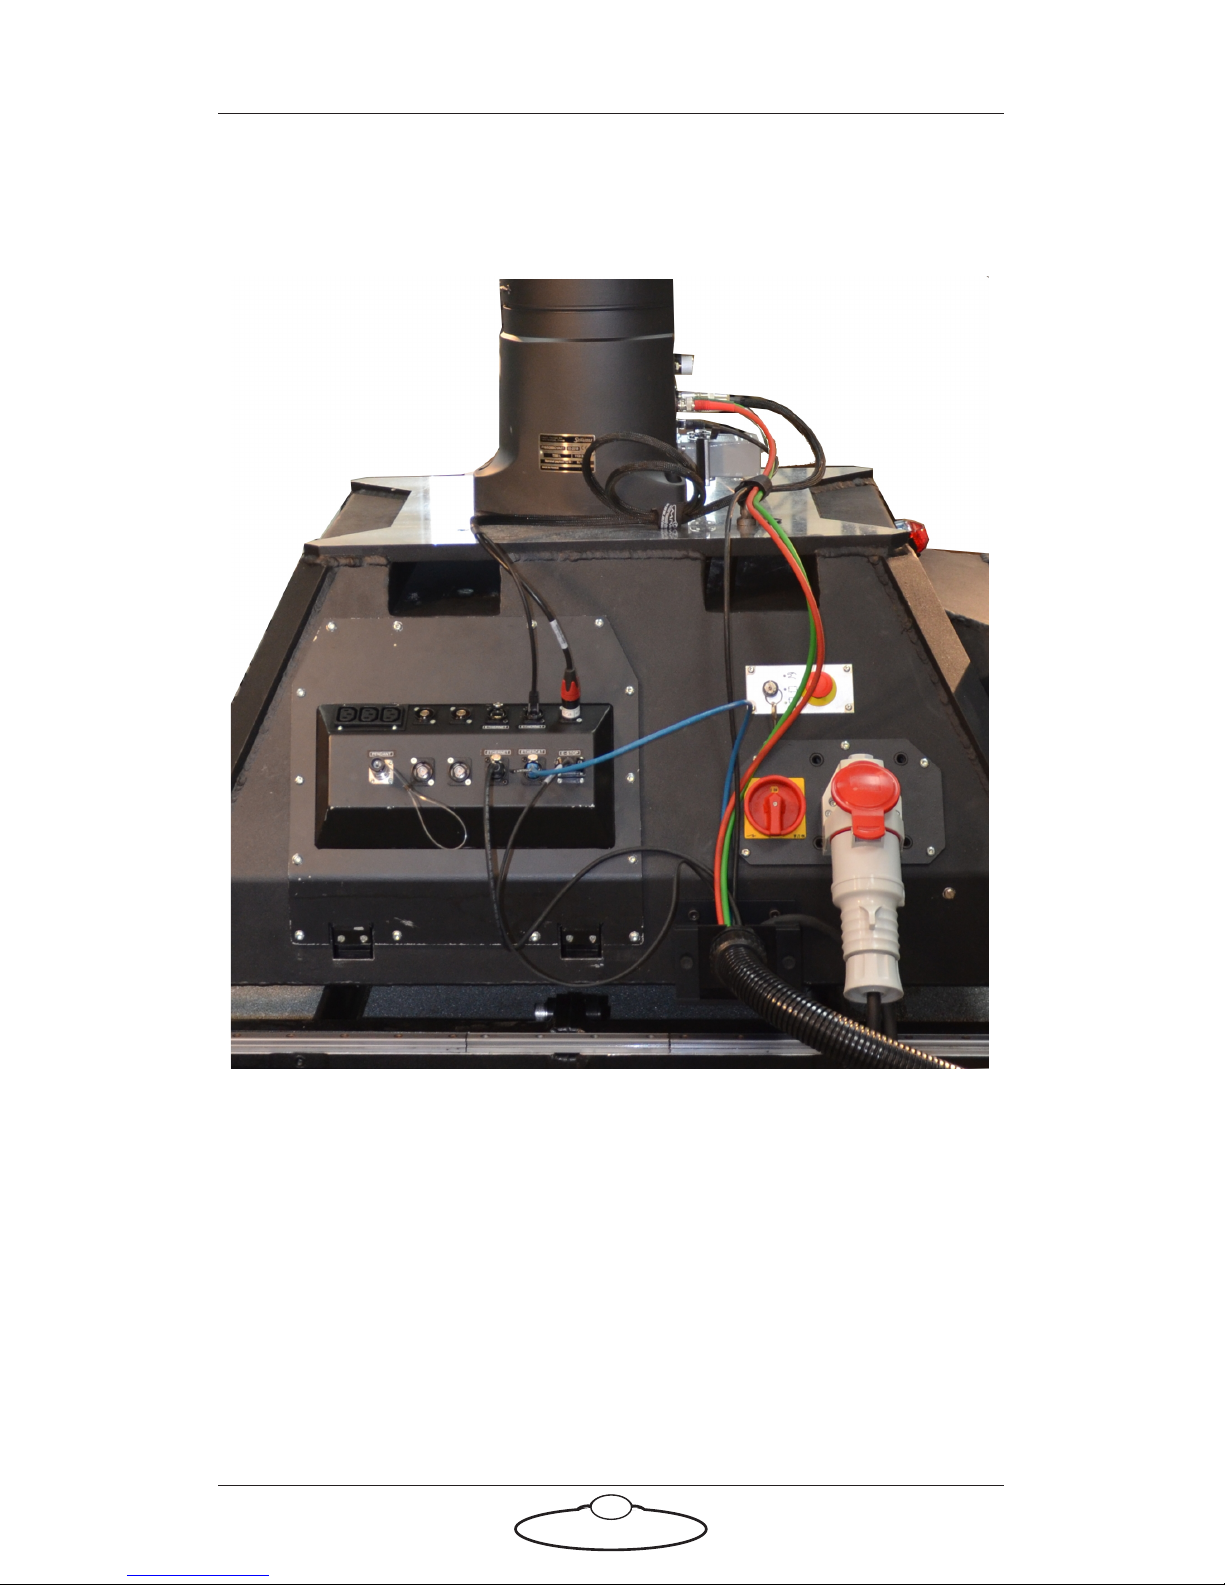
Picture of Bolt Junior connections:
Page 15
Bolt Junior Quick Start Guide
11
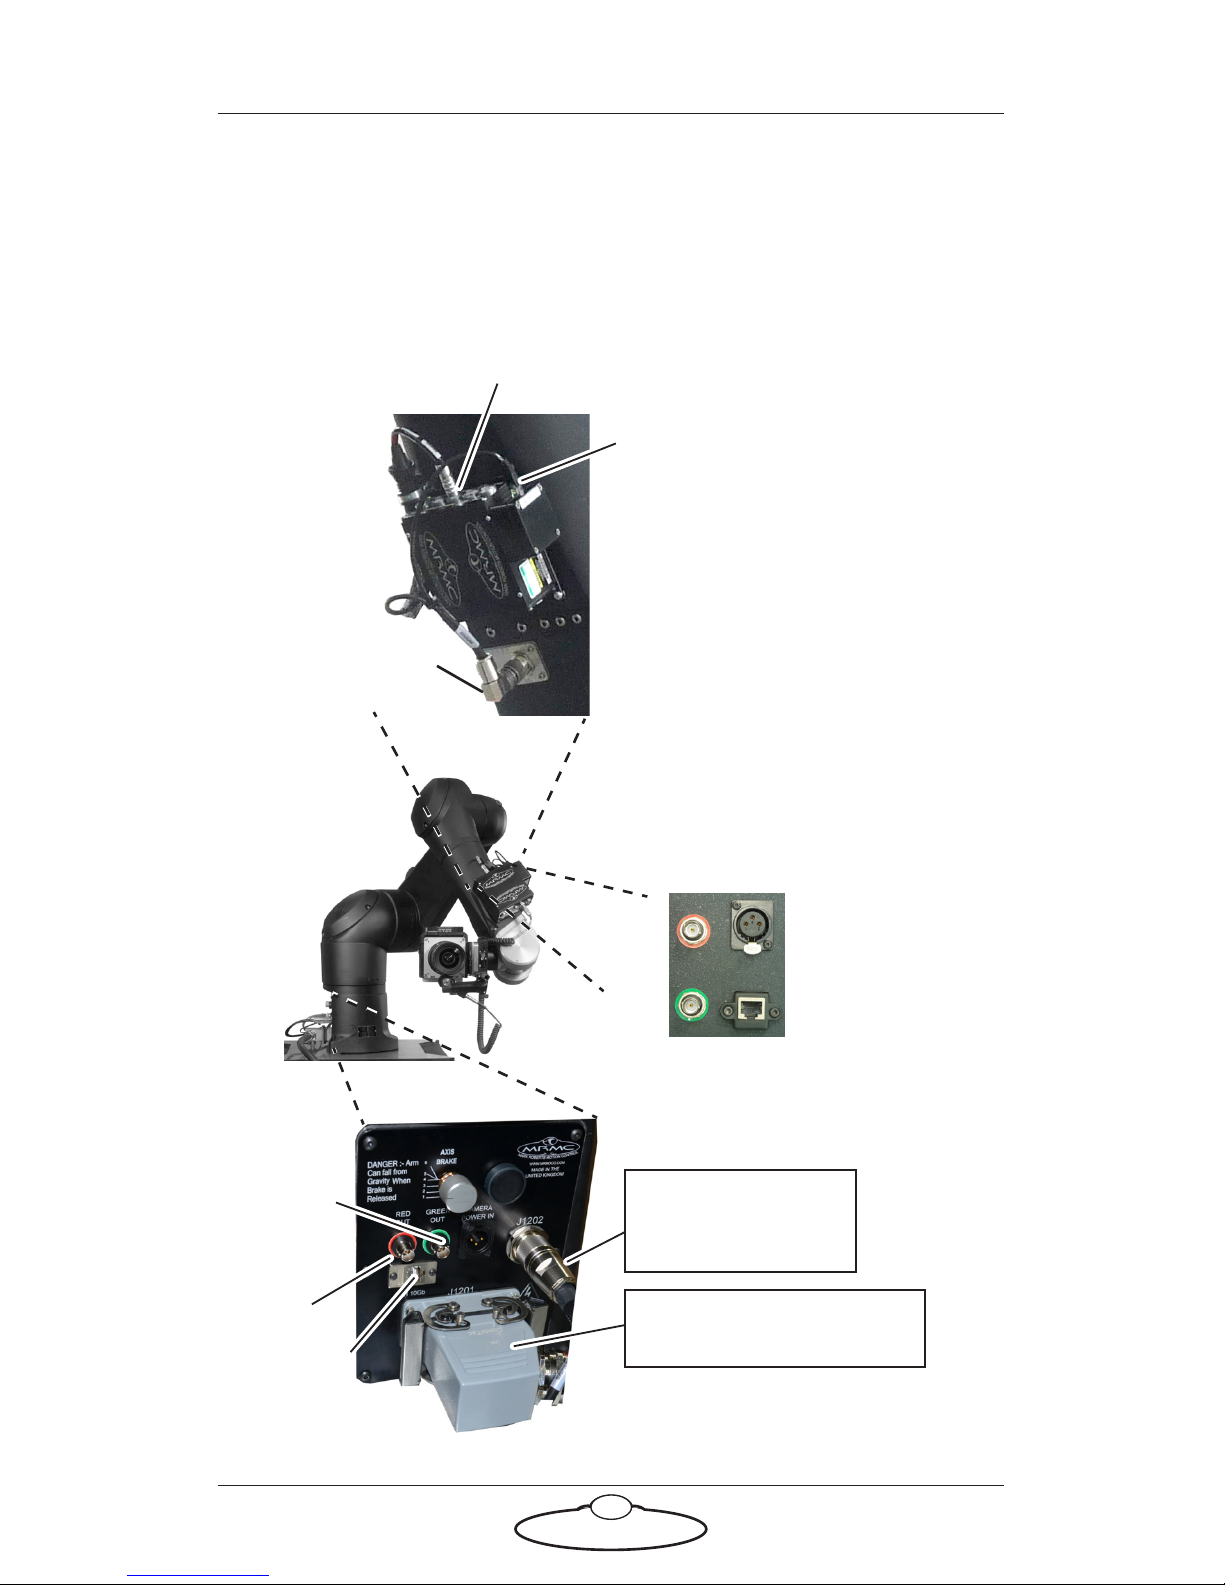
Bolt Junior arm connectors for Ulti-box and
camera
The connections that go through the Bolt Junior arm are shown below.
These are for the Ulti-box mounted on the arm, and for the camera that
you mount in the cage at the end of the arm.
POWER output:
24-48 Volts DC
POWER input: 24-48 Volts DC
Video 2
Video 1
ETHERNET
POWER input for camera:
24-48 Volts DC
J1202: Power input
and Ethernet for the
Ulti-box
Additional connectors
for the camera (exact
positions may vary)
ETHERNET
Video 1
Video 2
Power and Ethernet
for the Ulti-box
Ulti-box, which provides various
connectors for camera and lens
controls. For details see Ulti-box
connector summary on page 28.
ETHERNET for the Ulti-box
for camera
for camera
10GB
Page 16
Bolt Junior Quick Start Guide
12
Starting up the Bolt Junior system
Once you have attached all the cables, you power up the rig by switching
on the components in the order described below.
1. Make sure you have secured the area around Bolt
Junior. Put up guard rails around Bolt Junior (and the
track) as necessary, and tell others on the set that you
are now powering up the rig.
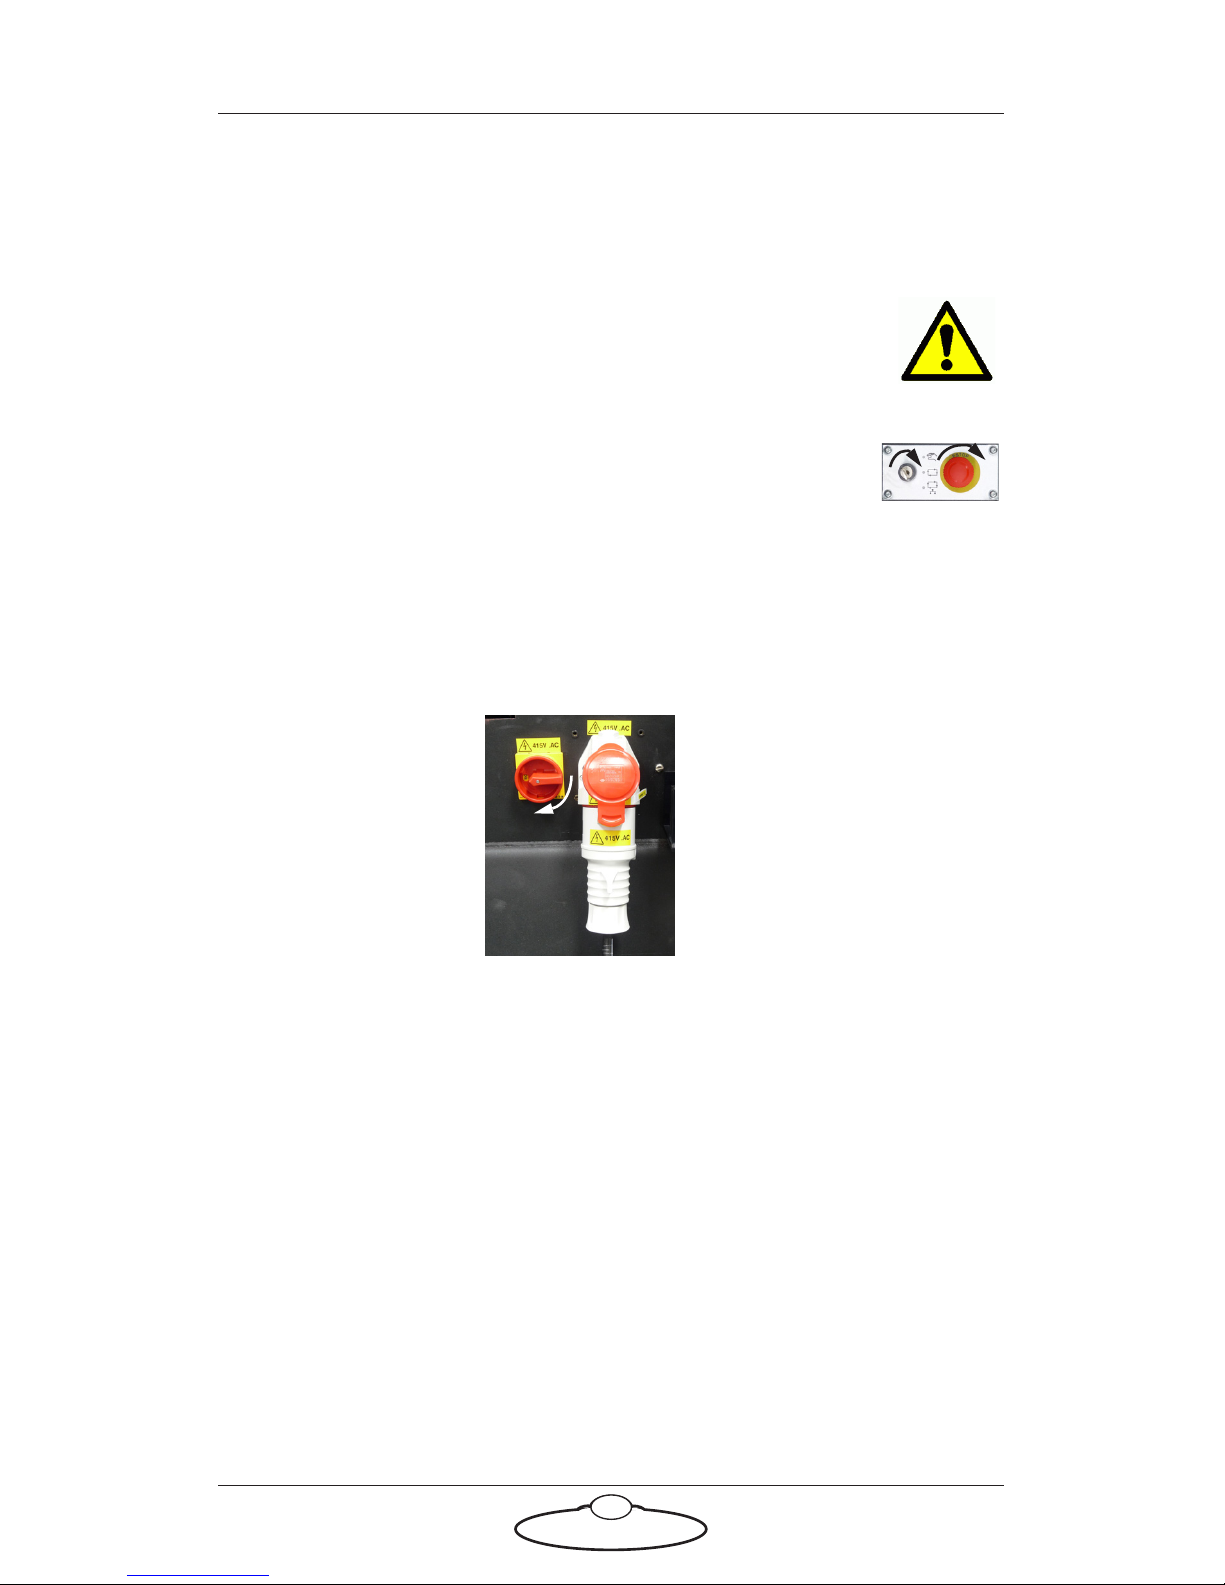
2. Release the E-stop on the Bolt Junior Base by turning
the red button clockwise until the button pops up. Also
make sure the key is in the clockwise position. Do not
release the other E-stop by the computer stack yet.
3. Power up Bolt Junior itself as follows:
The Bolt Junior power-up sequence takes about three minutes.
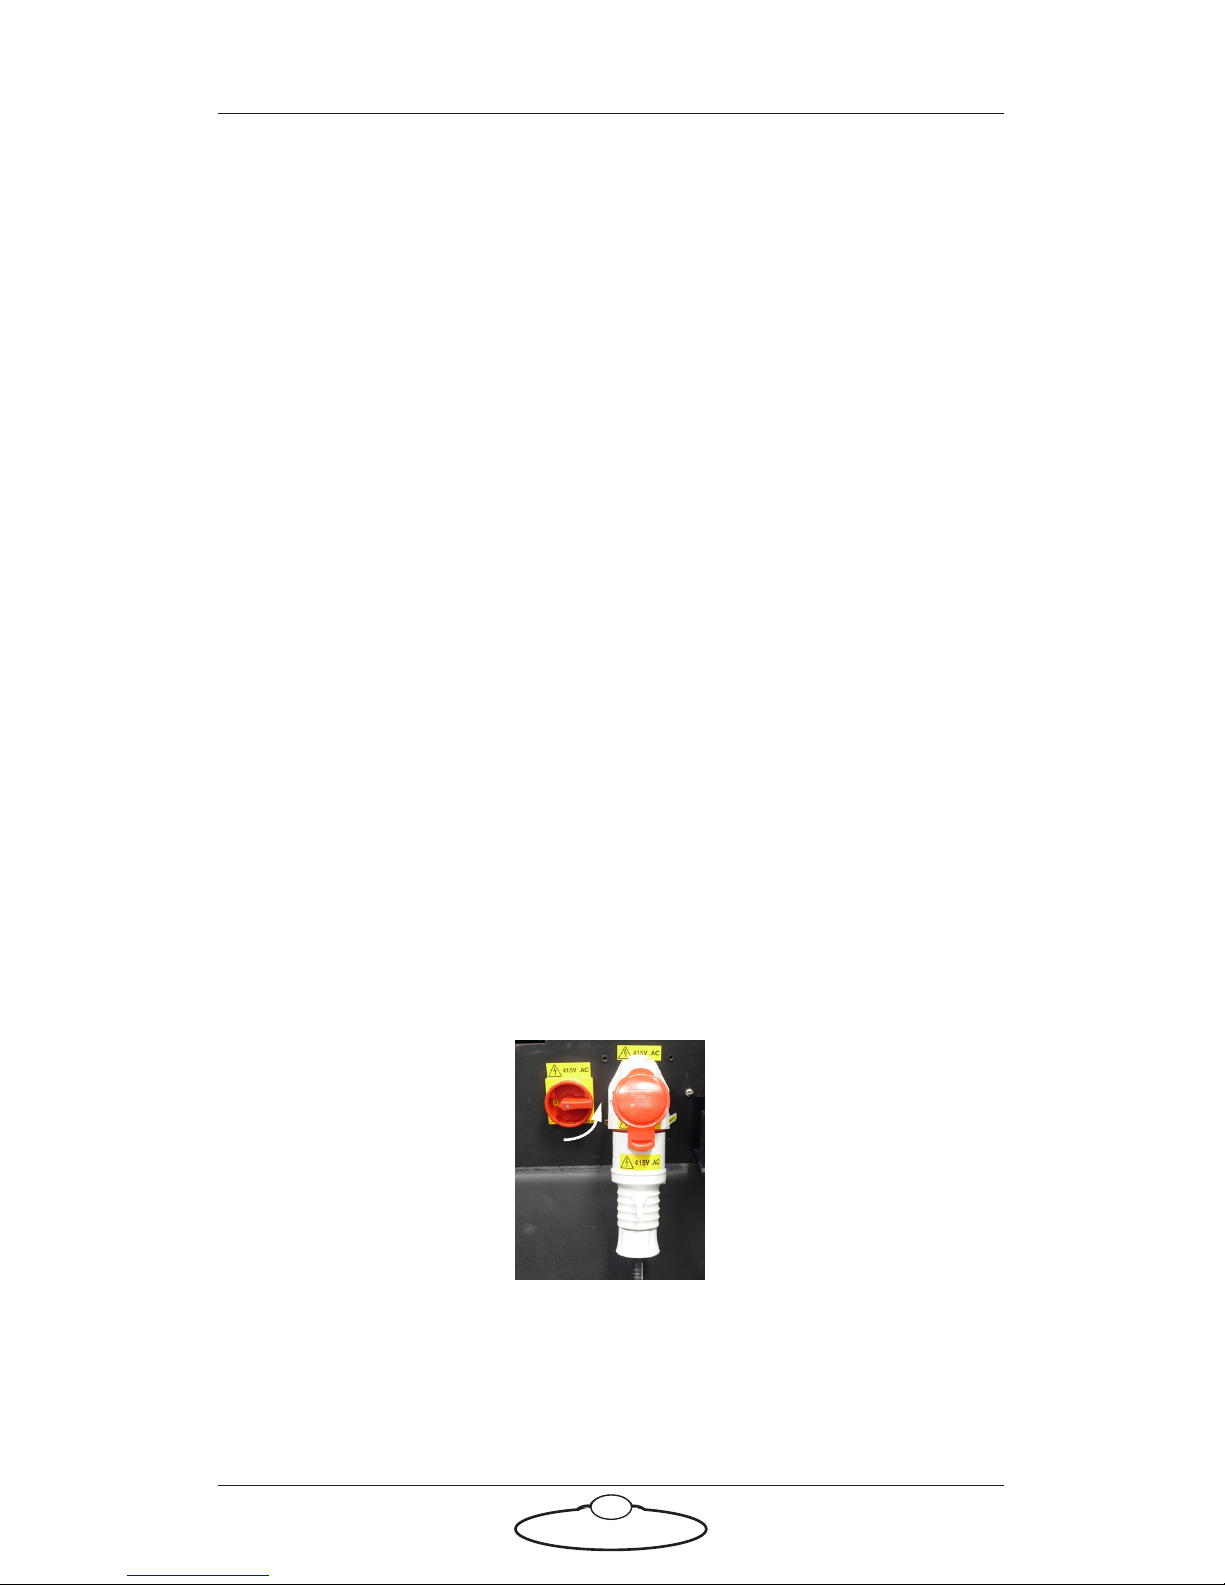
Turn on the power switch on
the side of the Bolt Junior
Base.
Page 17
Bolt Junior Quick Start Guide
13
4. Power up the Flair computer system and all of its components,
including the RT-14 interface box. You can do this while the robot is
powering up (step 3). Do not start the Flair application yet.
5. After the robot has finished powering up (step 3), the cifX board in
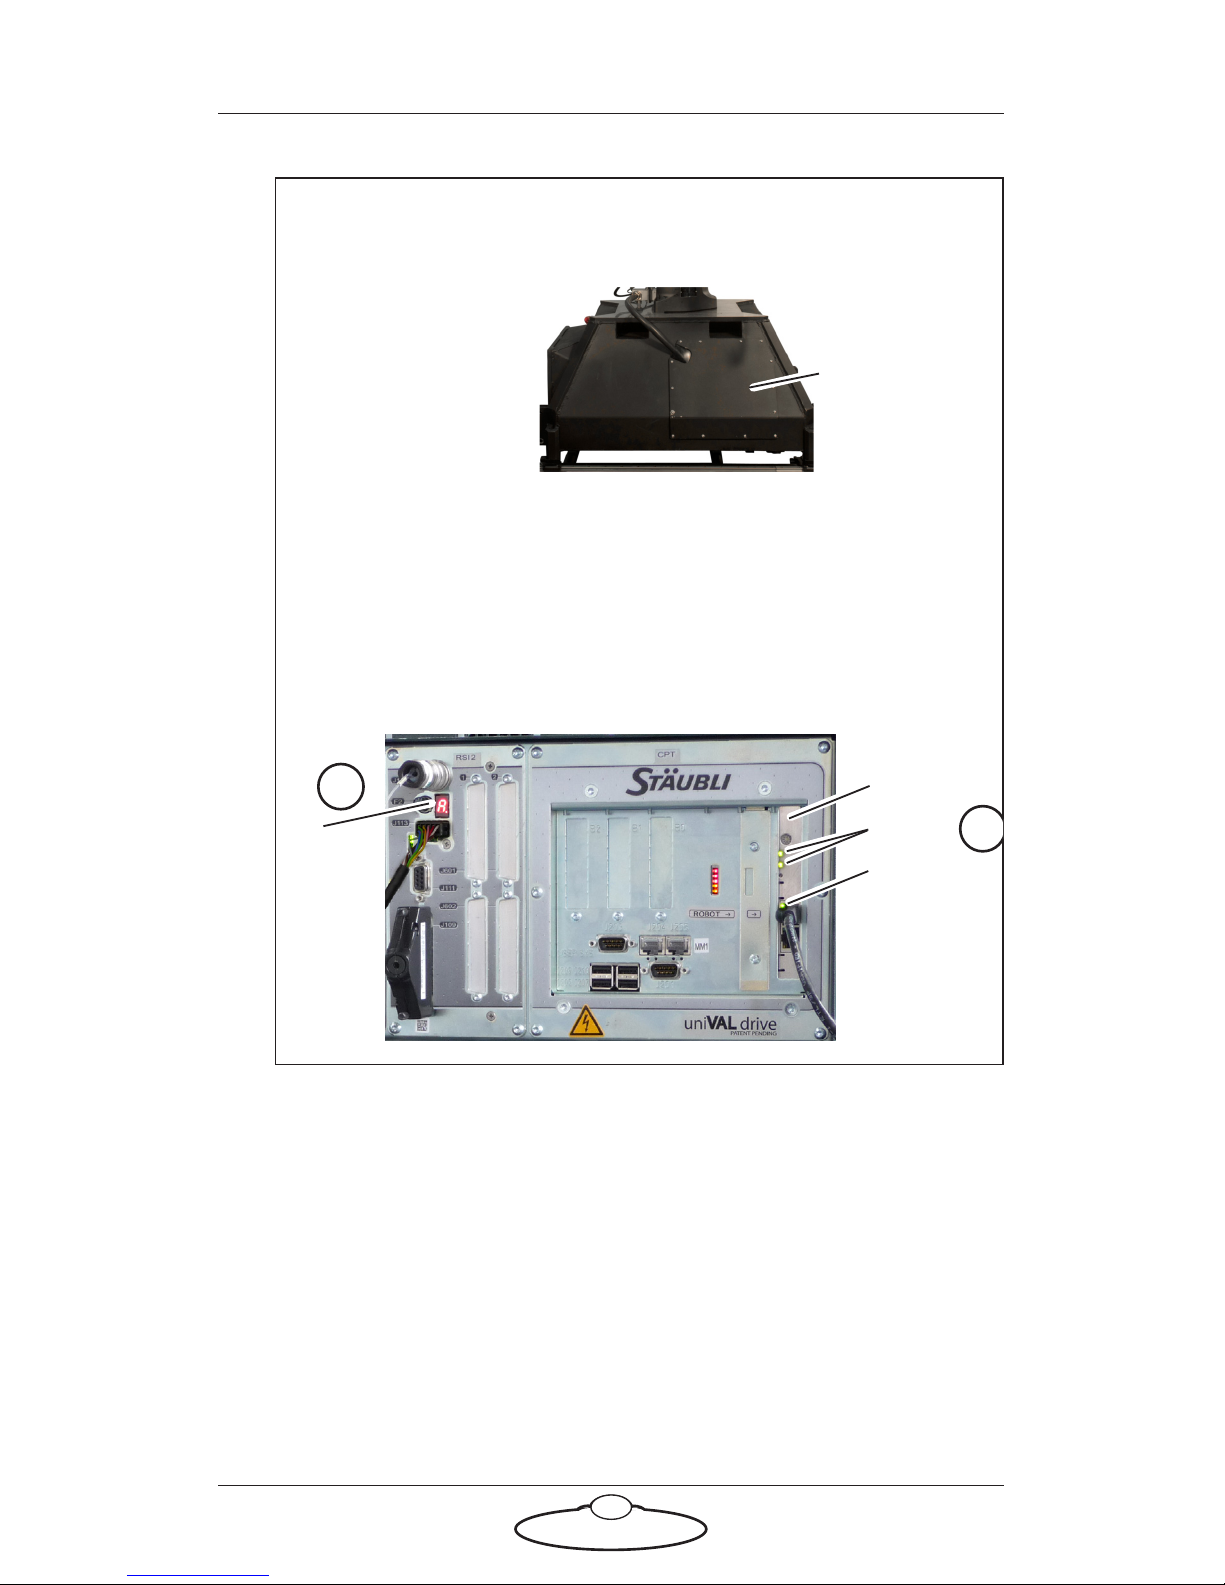
the Flair PC display two steady lights and one blinking light (see
previous diagram).
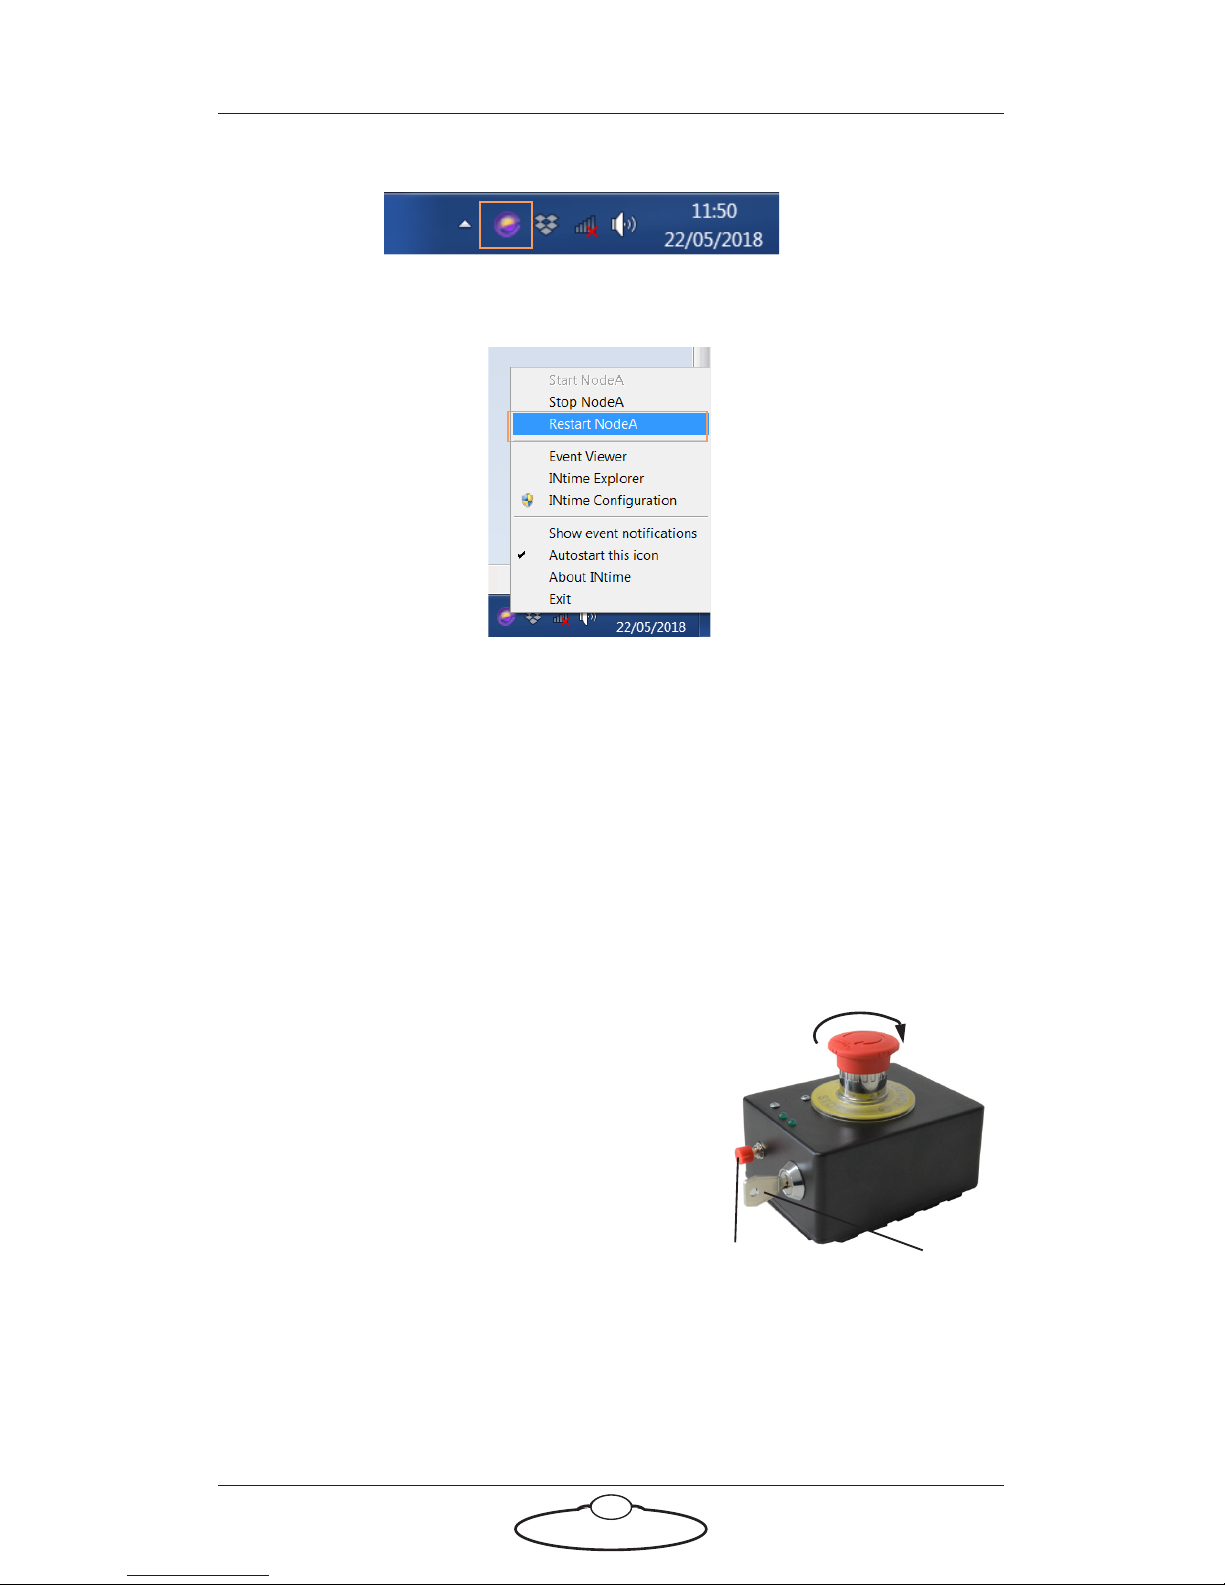
If the cifX board lights do not show as above after about three
minutes, then close Flair and restart INtime as follows:
Hint
The Stäubli CS8 is
housed inside the
Bolt Junior Base,
which you will not
need to access under
normal
circumstances.
However, in case of
a fault, you can
access CS8 by unscrewing the bolts on the plate covering the
CS8 in Bolt Junior Base.
When the power-up sequence has completed, the Stäubli CS8
shows an “A” on its display.
Bolt Junior
Base plate
covering
CS8
“A”
3
5
Steady
Blinking
cifX board
Page 18
Bolt Junior Quick Start Guide
14
5.1 In the Windows Taskbar, right-click the INtime icon.
5.2 Select Restart NodeA.
6. On the Flair PC, start the Flair application by double-clicking on the
Flair icon on the Desktop.
Flair automatically loads the relevant firmware into all attached axis
boards, including:
The quad board that runs the track motor The Ulti-box that is
mounted on the Bolt Junior arm
Any additional interface boxes that are attached to the
computer stack
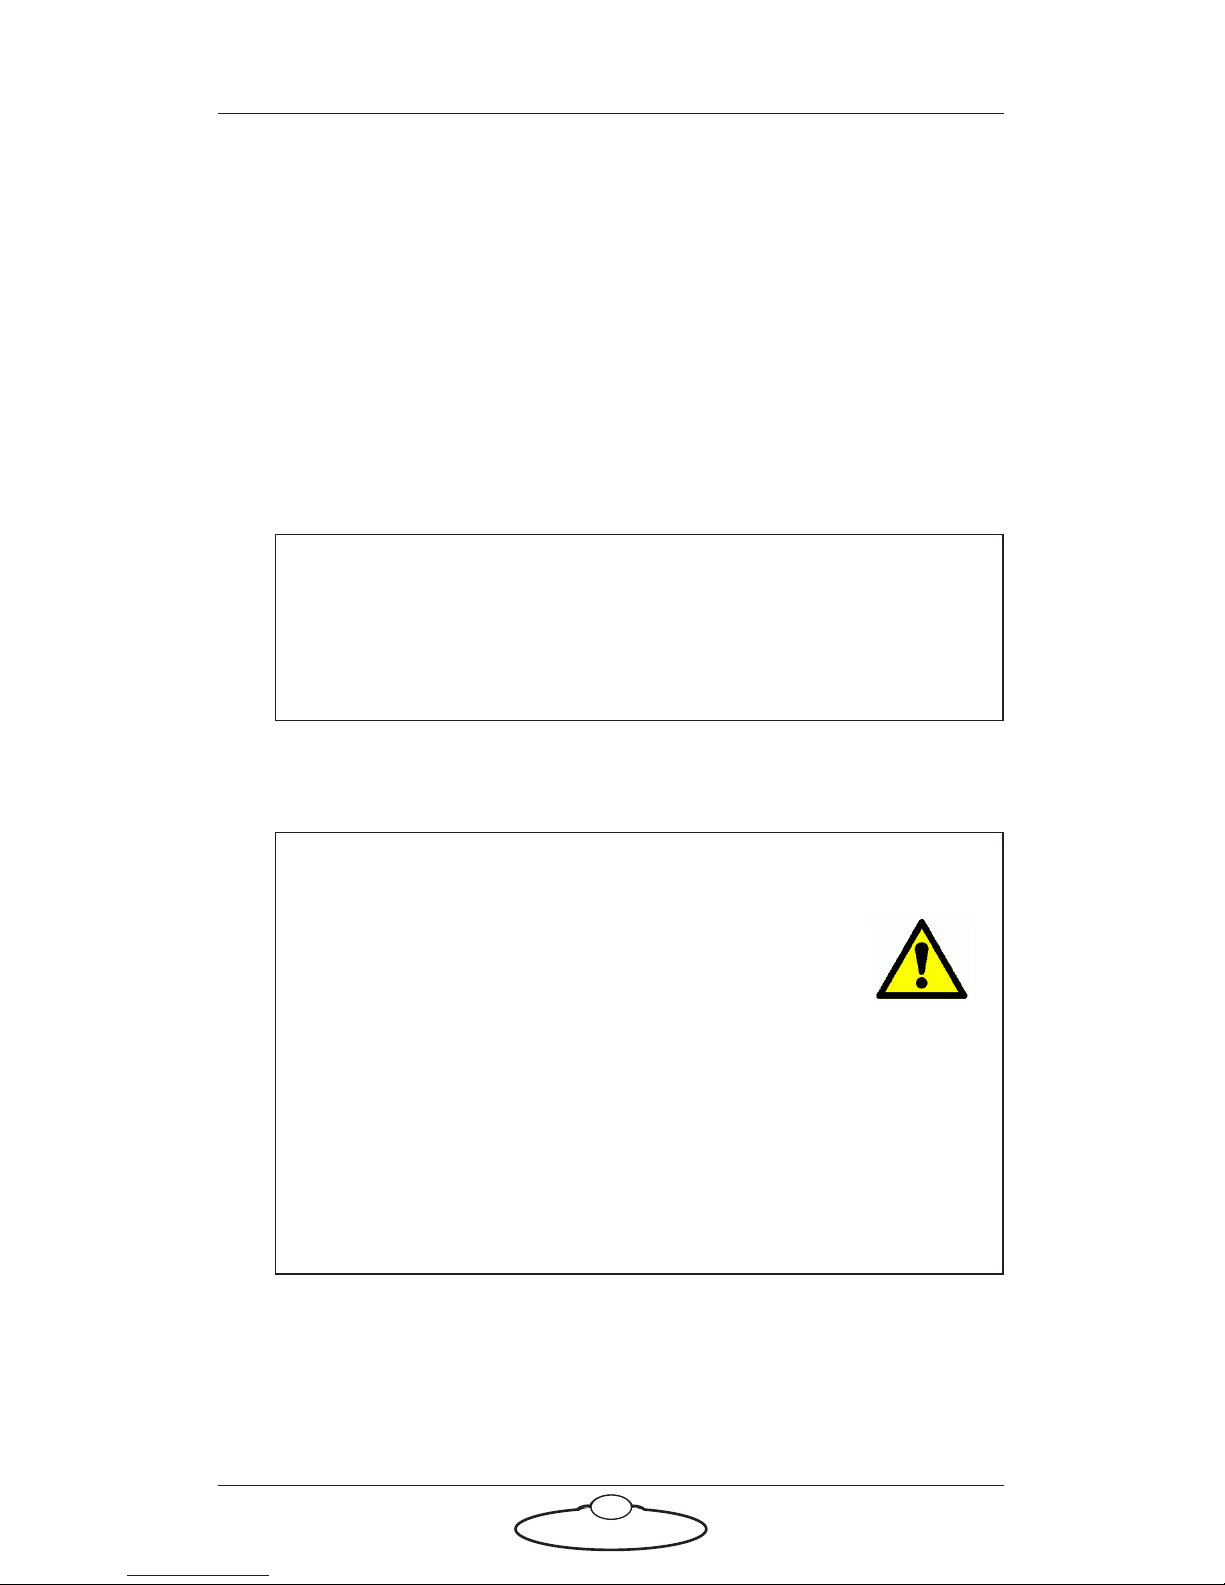
7. Release the E-stop that is plugged into
the computer stack, by turning the
button clockwise until the red button
pops up and then pressing the Reset
button. Also make sure the key is in
the vertical position. The horizontal
position of the key bypasses E-stop
from Hand Held box and Flair.
Therefore, the key should not be kept
in horizontal position when using Bolt
Junior except for testing purposes.
Once all E-stop buttons on the system are up, the Stäubli CS8 display
shows “U”.
Reset button
Key
Page 19
Bolt Junior Quick Start Guide
15
8. Zero the axes as required in Flair. The Bolt arm itself does not
require zeroing but you need to zero other axes such as:
The track: To do this you use the Zero > Home Axis > Track
menu option.
Any external Lens Control Motors (LCMs) that you are using.
To zero these you first set the focus to infinity (), zoom to
wide-angle (zoomed out all the way), iris/aperture to wide
open and then use the relevant Zero > Direct Zero Axis menu
option to set those lens positions as the zero points in Flair.
9. In Flair, click on the Engage Robot button.
10. In Flair, move the Bolt Junior arm to its home position (rotated
straight forward and tucked under).
11. Set the soft limits for the rig axes in Flair as required:
Arm position limits
Track limits
Hint
You use the Track button in Flair to toggle the track on and off,
independently of the Engage Robot/Disengage Robot button
that you use to toggle the Bolt Junior arm on and off.
Hint
If the Bolt Junior arm is in a backward or reversed
starting position, the arm might swing overhead or
around the side to reach the home position,
possibly striking the walls, ceiling, or other rigging!
If the rig is in an enclosed space or near other equipment, it is
recommended that you do the following:
• Manually move the arm close to its home position before
Homing it.
• When you home the rig, have one hand ready on the
E-stop in case you need to stop the rig quickly.
Page 20
Bolt Junior Quick Start Guide
16
Lens Control Motor limits (if using external LCMs)
Bolt Junior start-up summary
1. Secure the area
2. Release the E-stop on the rig
3. Switch on Bolt Junior
4. Switch on the Flair PC
5. Check networking lights after three minutes; Start Robot if needed
6. Start Flair
7. Release the E-stop on the computer stack
In Flair:
8. Zero the track and Lens Control Motor axes
9. Engage Robot
10. Home the arm, carefully
11. Set the soft limits
The rig is now ready to use.
Page 21
Bolt Junior Quick Start Guide
17
Shutting down the Bolt Junior system
1. Move Bolt Junior to its Home position, for both the arm and the
track.
or...
If you are going to transport Bolt Junior to a new location, put the
Bolt Junior arm into its transport position. You can do this either by
using Flair (although you might have to reset the soft limits to reach
the transport position) or by moving the arm manually. For details
see page 18.
2. In the Flair software, click on the Disengage Robot button.
3. In the Flair software, disengage the track by toggling off the Track
button.
4. Press down all E-stop buttons:
On the computer stack
On the Bolt Junior Base
5. Close the Flair software.
6. Shut down Windows on the Flair PC.
7. Turn off Bolt Junior as follows:
To remove Bolt Junior from the track see Mounting Bolt on the track in
the separate Precision Track Quick Start Guide and follow the instructions
there in reverse order, to attach the trolley wheels, detach the pinch motor
wheels and remove the rig from the track bearings.
Turn off the power switch on
the side of the Bolt Junior
Base.
Page 22
Bolt Junior Quick Start Guide
18
Bolt Junior shut-down summary
1. Move Bolt Junior to the Home or Transport position
2. In Flair: Disengage Robot
3. In Flair: Toggle off the Track
4. Press down all E-stops
5. Close Flair
6. Shut down Windows
7. Switch off Bolt Junior
Moving the Bolt Junior arm by hand
In some circumstance you need to move the Bolt Junior arm manually
with your own hands. For example:
• Recovering from a software lock-up. For example if momentum has
carried the arm outside the soft limits, the software might refuse to
move the arm to get back inside the limits.
• Recovering from a hardware lock-up. If momentum or a
programming error moves the arm against its internal hard limits or
if the camera platform gets stuck against another part of the arm, the
motors might not be able to back off from this position without
tripping out.
• Putting the arm into transport position, to make the Bolt Junior
volume as small as possible so it will fit into a truck. You can do this
with Flair software (although you will probably need to change the
soft limits) but if you forget to do so before shutting down the Flair
computer then you can do it by hand.
Page 23
Bolt Junior Quick Start Guide
19
To move the Bolt Junior arm by hand:
1. Make sure that robot itself has power and is switched on. The brakes
are on when the unit is switched off, so if you want to move the arm
by hand, Bolt Junior must have power and be switched on.
2. If the robot is connected to a running Flair PC, click on the
Disengage Robot button in Flair.
Hint
Moving the Bolt Junior arm by hand is usually a two-person job —
one to operate the Brake Release switch and button and one to move
the arm.
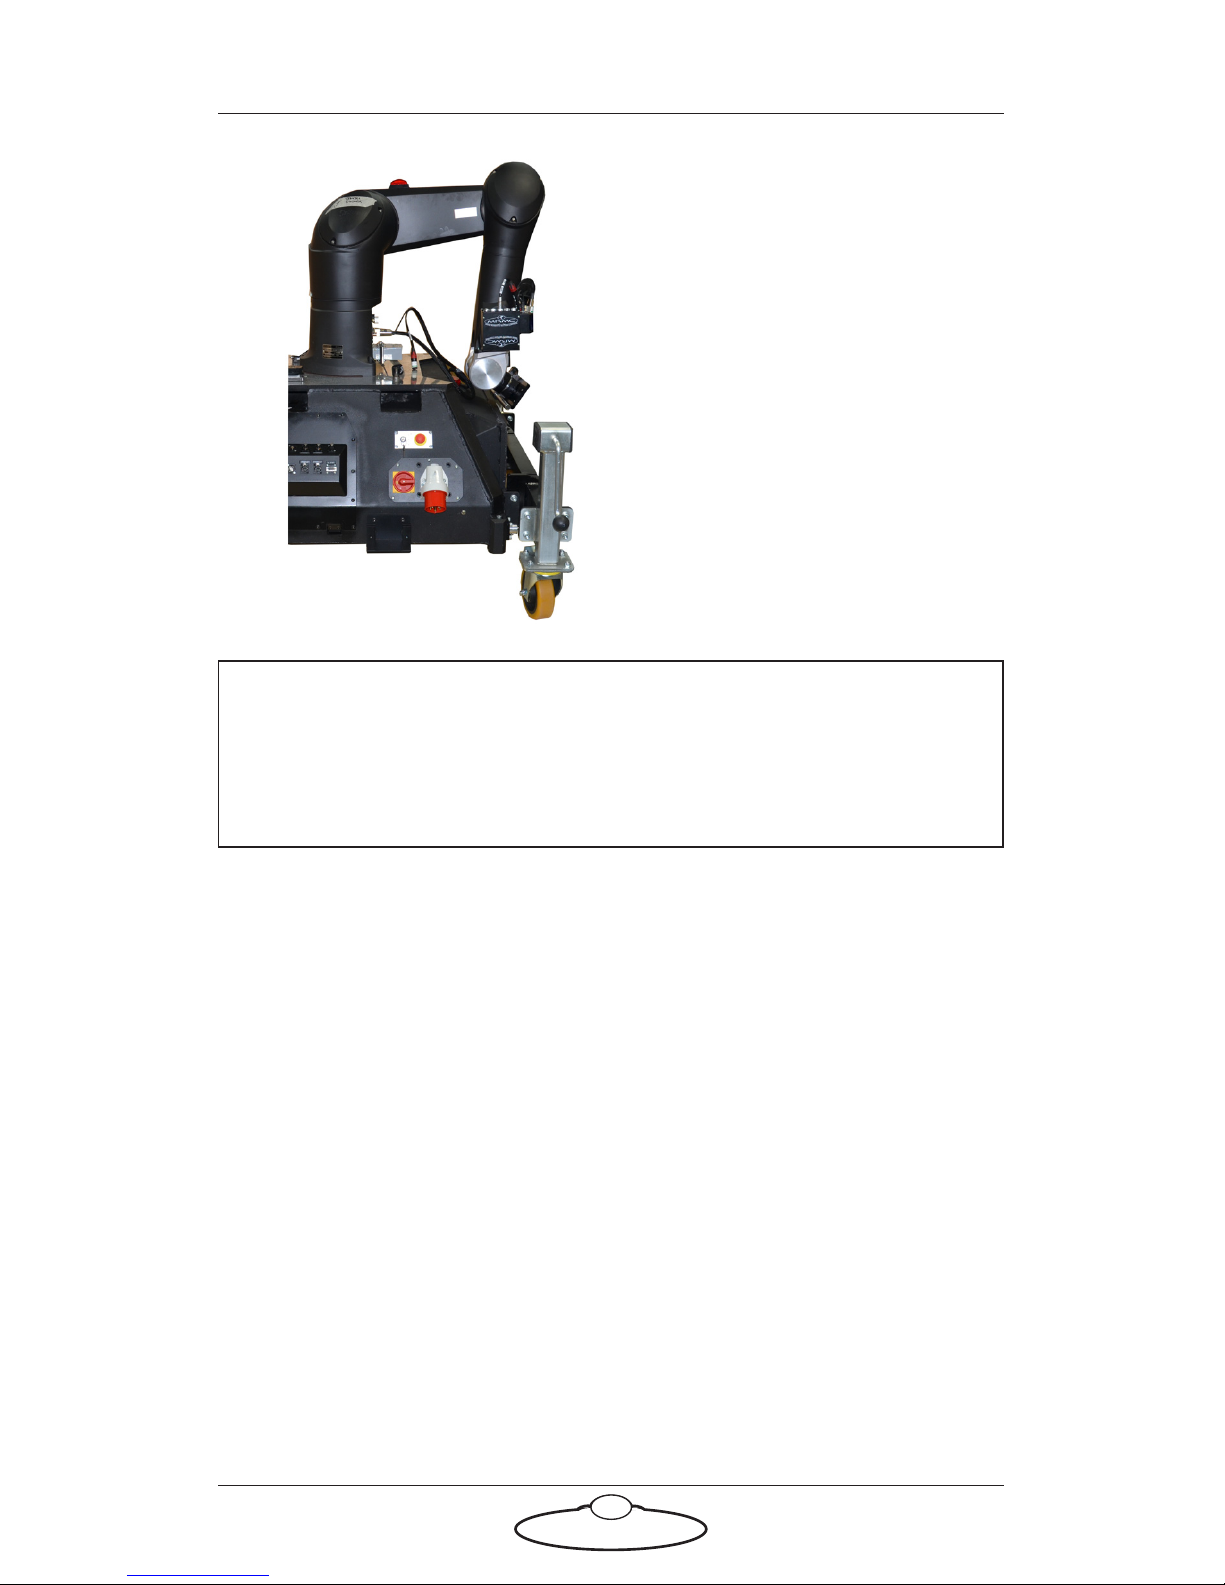
Transport position:
• Arm rotated forward and tucked
under.
• Camera platform perpendicular
to base slope, above the wheel
unit, with about 3 cm clearance
between it and the base.
Page 24
Bolt Junior Quick Start Guide
20
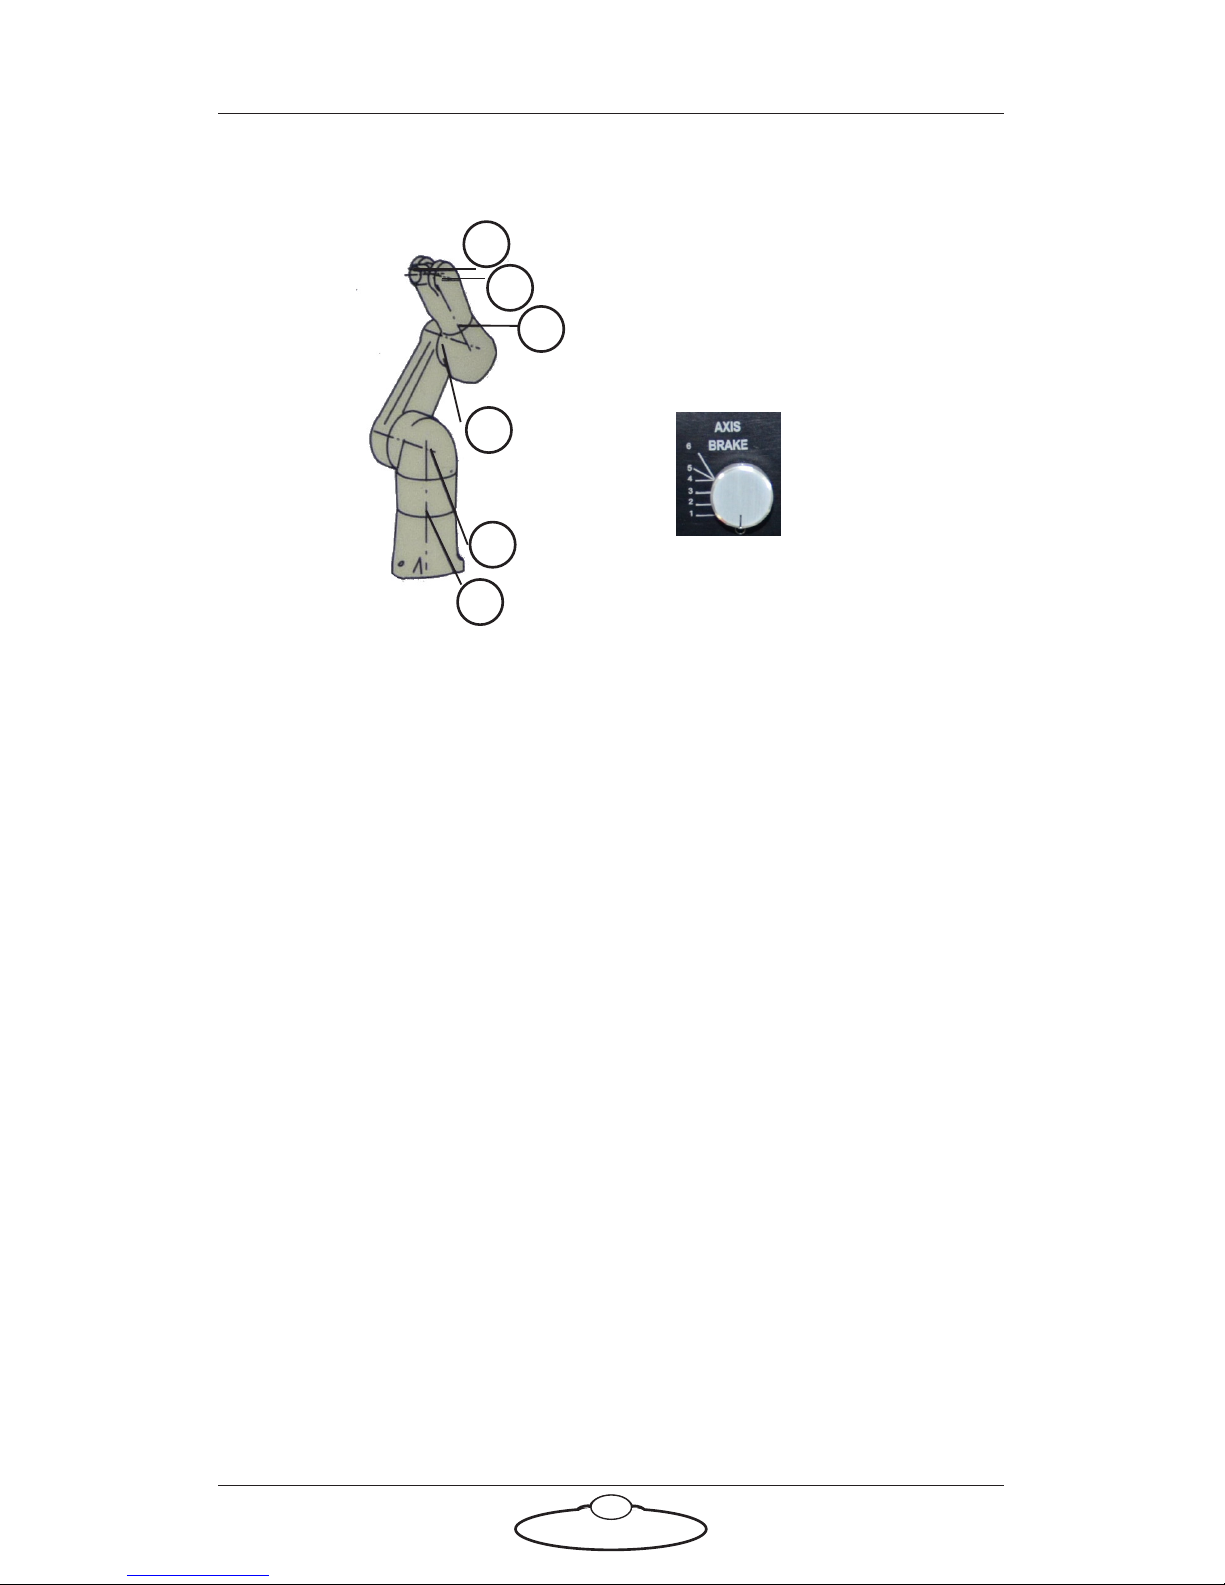
3. Person 1: Use the Brake Release Switch to select which Bolt Junior
axis you want to move.
4. Person 2: By hand, securely hold the portion of the arm that you
want to move so it does not fall when you release the brake.
5. Person 1: Press and hold the Brake Release button.
6. Person 2: Move the arm by hand.
7. Person 1: Release the Brake Release button.
8. Repeat steps 3 to 7 to move all the axes you want.
9. When you have finished, turn the Break Release Switch to the ‘0’
position, and power down.
1
2
3
4
5
6
Brake Release Switch should be
in the ‘0’ position when not
moving the robot by hand
Axes positions in the
Staubli arm
Page 25
Bolt Junior Quick Start Guide
21
Notes
Page 26
Bolt Junior Quick Start Guide
22
Bolt Junior Quick Start GuideBolt JuniorQuick Start Guide
Appendix 1 Troubleshooting
Typical symptoms, causes, and actions
Symptoms Cause and/or action
Flair fails to establish a
network connection to
the Bolt Junior
controller (the Stäubli
CS8) over the
ETHERCAT cable.
Try a different cable. The cable between the
cifX boards in the Flair PC and Stäubli CS8
needs to be a high quality, fault-free,
straight-through (that is, not cross-over)
Ethernet cable.
Check that all cables are connected correctly
and that all devices, including the Ethernet
hubs, have power.
Check the order in which you are powering up
the devices (page 12).
Make sure you have allowed enough time for
the Bolt Junior/Stäubli CS8 unit to completely
power up (with the cifX board lights displaying
the correct pattern) before you double-click on
the Start Robot icon on the Flair PC Desktop.
Bolt Junior won’t move Make sure you have enabled Bolt Junior in
Flair (click on the Engage Robot button).
Make sure all of your E-stop buttons are up,
and that you have pressed the Reset button on
each E-stop (if it has one). When they are all
up, the Stäubli CS8 panel displays a “U”.
If you have moved the Bolt Junior arm by hand
with the Brake Release Unit, make sure you
have replaced the Brake Release Plug in the
socket when you have finished. For details see
Moving the Bolt Junior arm by hand on page 18.
Page 27
Bolt Junior Quick Start Guide
23
Notes
Page 28
Bolt Junior Quick Start Guide
24
Bolt Junior Quick Start GuideBolt JuniorQuick Start Guide
Appendix 2 Bolt Junior panels
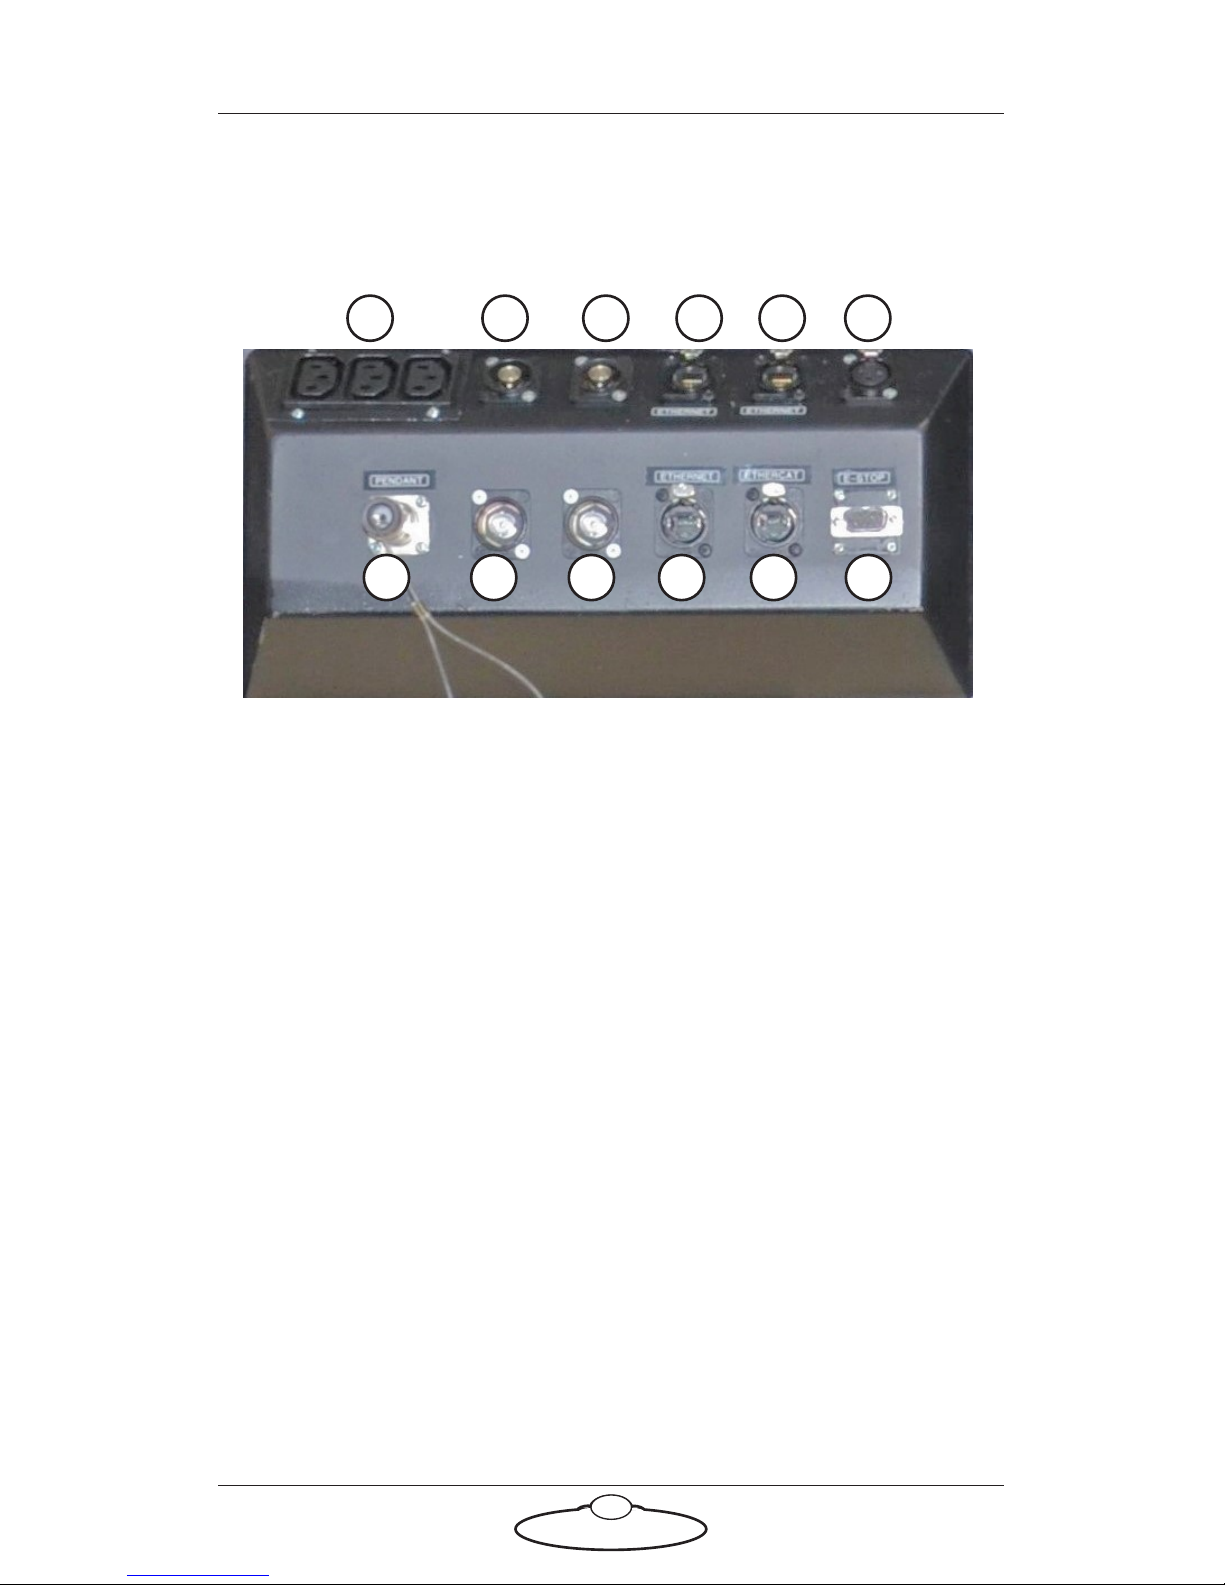
Bolt Junior Base panel connector summary
1. 240V AC output, for general use by additional devices that you want
to mount on the base.
2. VIDEO 1 IN input connector for the video 1 signal from the camera.
This has a straight-through internal connection to the VIDEO 1
OUT connector (8).
3. VIDEO 2 IN connector for the video 2 signal from the camera. This
has a straight-through connection to the VIDEO 2 OUT connector
(9).
4. ETHERNET (Not used)
5, 10. ETHERNET connectors for communications between multiple
Ethernet devices on the rig. These two connectors share a common
Ethernet hub within the Bolt Junior Base. You ordinarily attach one
of these to the computer stack (via the umbilical cable) and one to
connector J1202 on the base of the arm to service the Ulti-box
mounted on the arm.
6. 48V OUT power connector. You usually use this to power the
Ulti-box (and its attachments) on the Bolt Junior arm, by attaching a
cable from this connector to the J1202 connector on the arm.
4321 5 6
10987 11 12
Page 29
Bolt Junior Quick Start Guide
25
7. PENDANT connector, for attaching a Teach Pendant to the rig. This
is required for the rig to operate, and should only be removed under
advice from MRMC support staff.
8. VIDEO 1 OUT connector for the video 1signal from the camera.
This has a straight-through connection to the VIDEO 1 IN
connector (2).
9. VIDEO 2 OUT connector for the video 2signal from the camera.
This has a straight-through connection to the VIDEO 2 OUT
connector (3).
11. ETHERCAT connector. You use this to connect the cifX board in the
Stäubli CS8 unit (inside the Bolt Junior Base) to the cifX board in
the Flair PC, via the umbilical cable. The cifX Ethernet network is an
industrial grade high speed network used to control the Bolt Junior
motion, and is completely separate from the Ethernet network that
runs the Ulti-box and camera.
12. E STOP connector. You connect this to the E-stop button beside the
computer stack, via the umbilical cable.
Page 30
Bolt Junior Quick Start Guide
26
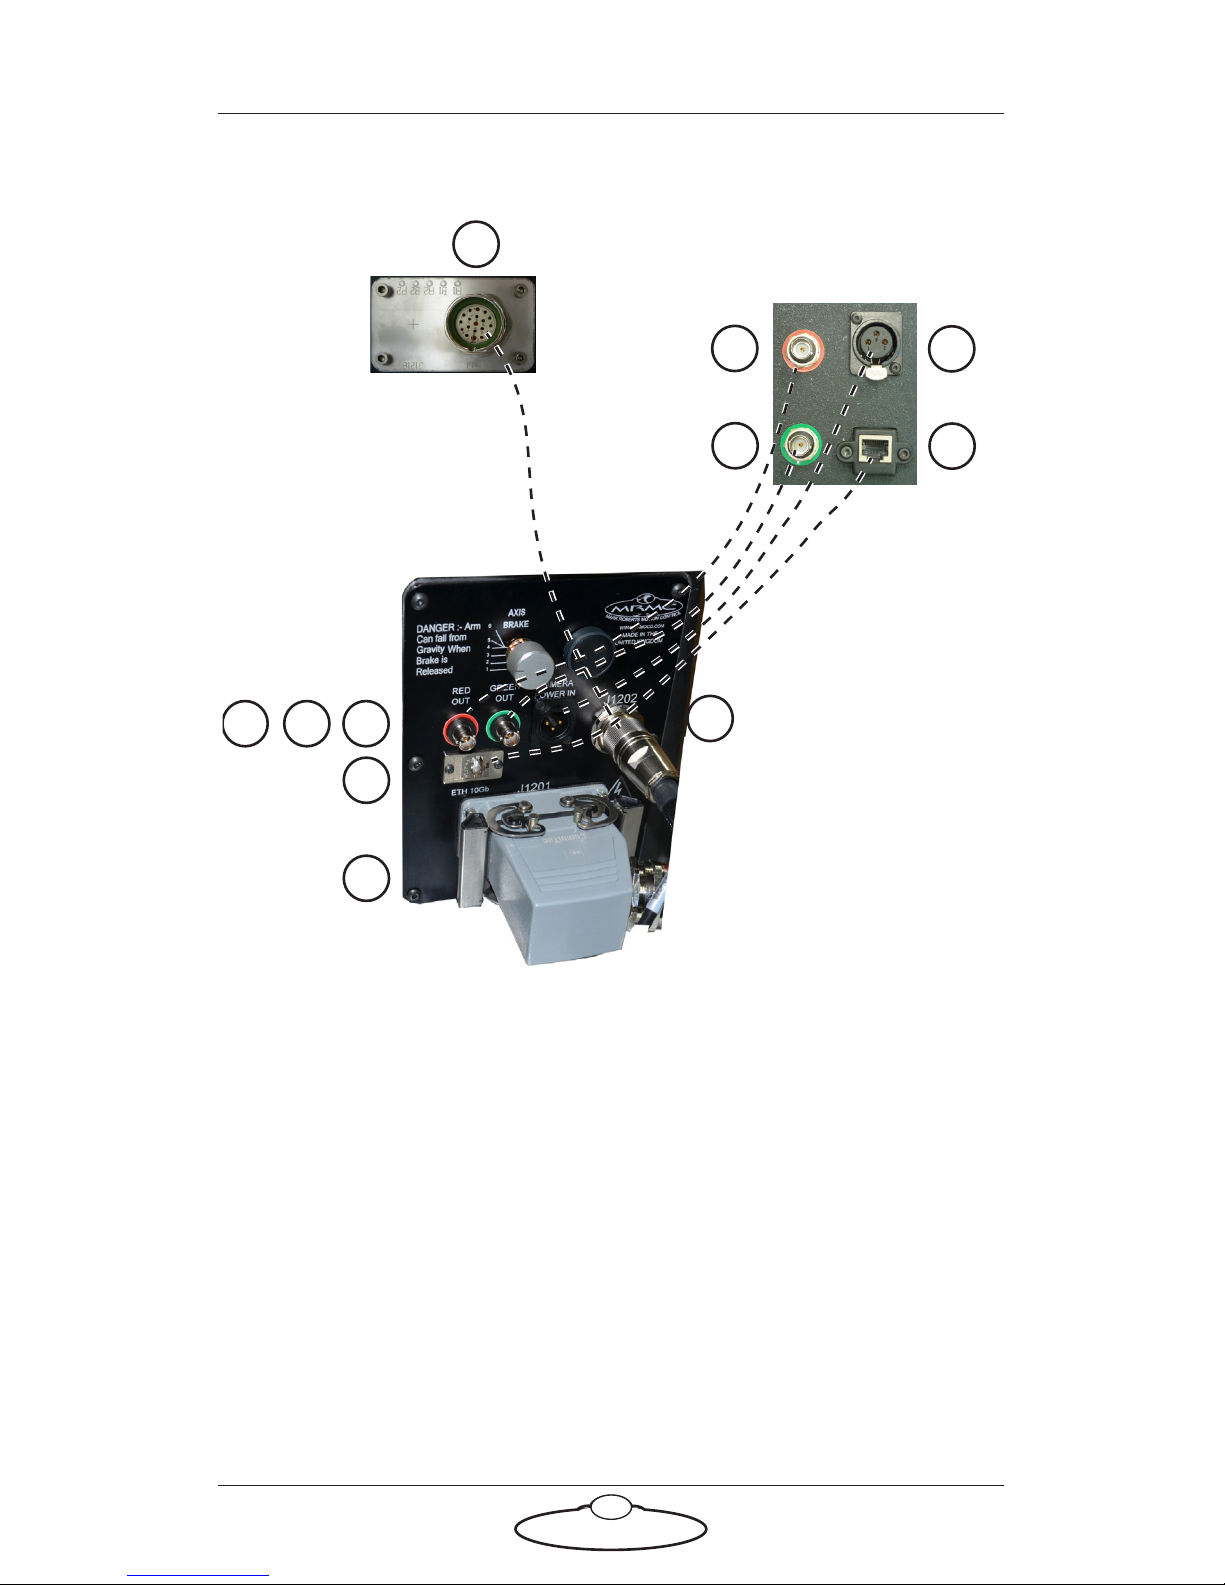
Bolt Junior arm panels connector summary
1. Ulti-box output connector. This supplies 48 Volts DC output and
Ethernet for the Ulti-box mounted on the arm. This has a
straight-through internal connection to the Ulti-box input
connector (6). This connector uses a special two-into-one cable that
attaches to the ETHERNET and POWER connectors on the Ulti-box
that is mounted on the Bolt Junior arm.
2. VIDEO 1 IN input connector for the video 1 signal from the camera.
This has a straight-through internal connection to the VIDEO 1
OUT connector (7).
3. VIDEO 2 IN connector for the video 2 signal from the camera. This
has a straight-through internal connection to the VIDEO 2 OUT
connector (8).
87
6
9
10
Camera connector panel
(exact positions of the
connectors may vary)
11
2
3
4
5
1
Arm base
panel
Ulti-box
supply
panel
Dotted lines show
the internal
straight-through
wiring connections
that go through the
Bolt Junior arm.
Page 31
Bolt Junior Quick Start Guide
27
4. 24-48 Volts DC output power connector. You can use this to
power the camera or other devices mounted on the camera
platform. This has a straight-through internal connection to the
24-48 Volts DC input power connector (9), so the output voltage
is whatever voltage you have put into connector 10.
5, 10. ETHERNET 10GB connectors (100 Mbits/sec rating) for
communications between the camera and the rest of the system. The
connection between these two connectors is a straight-through
internal connection through arm, and you ordinarily attach
connector 10 to the Ethernet hub that services the Ulti-box for one
of the Ethernet connectors in Bolt Junior Base.
6. Ulti-box input connector. This accepts 48 Volts DC power and
Ethernet for the Ulti-box mounted on the arm. This has a
straight-through internal connection to the Ulti-box output
connector (1). This connector uses a special two-into-one cable that
attaches to the ETHERNET and 48V OUT connectors on the Bolt
Junior Base.
7. VIDEO 1 OUT connector for the video 1signal from the camera.
This has a straight-through internal connection to the VIDEO 1 IN
connector (2).
8. VIDEO 2 OUT connector for the video 2 signal from the camera.
This has a straight-through internal connection to the VIDEO 2
OUT connector (3).
9. 24-48 Volts DC input power connector. You can use this to power
the camera or other devices mounted on the camera platform. This
has a straight-through internal connection to the 24-48 Volts DC
output power connector (4).
11. Stäubli controller connector. This is for the main cable that runs
between the Bolt Junior arm and the Stäubli CS8 controller unit,
which supplies both power and control to the arm. The Stäubli CS8
controller is housed inside the Bolt Junior Base.
Page 32
Bolt Junior Quick Start Guide
28
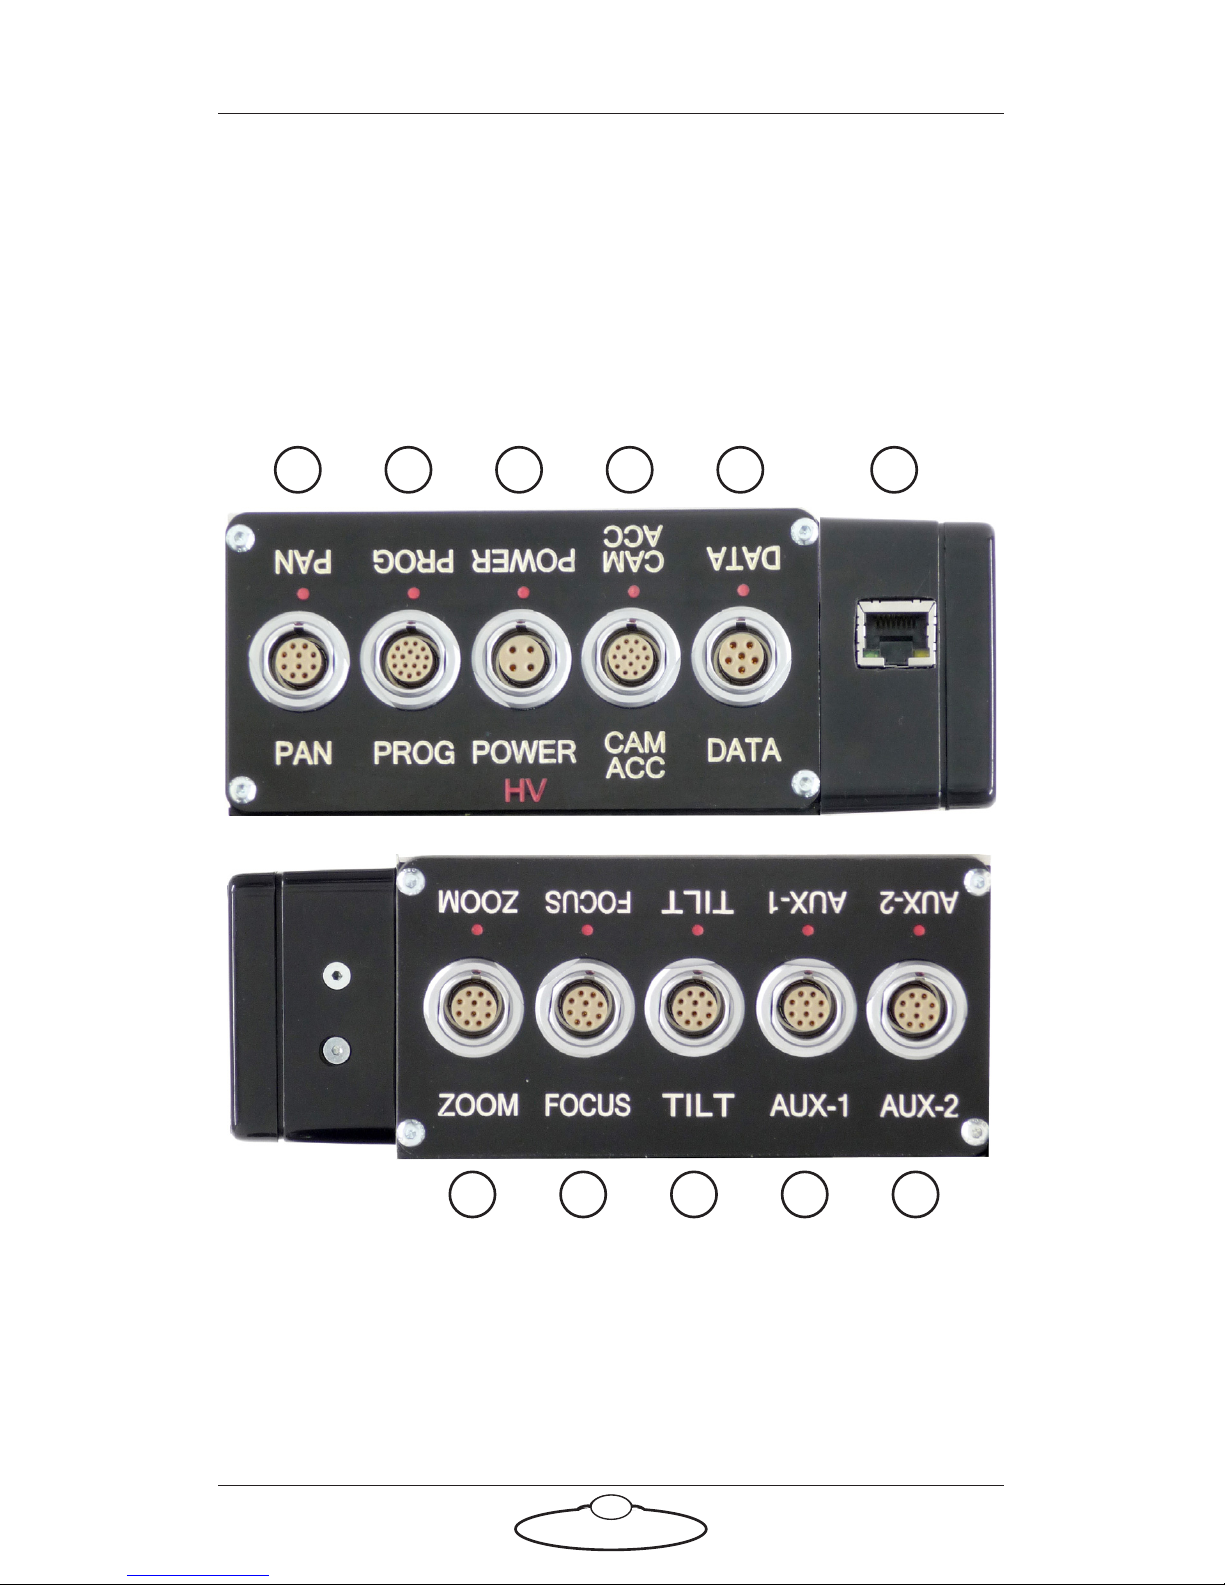
Ulti-box connector summary
The Ulti-box that is mounted on the Bolt Junior arm is a multi-purpose
interface box that is used to control servo motors on many MRMC heads
and Lens Control Motor (LCM) units. The Ulti-box offers versatile
connections for many camera and lens configurations although some of
the axes connectors such as PAN, TILT, and DATA are not ordinarily used
in the context of Bolt Junior, as Bolt Junior itself provides these features.
1. PAN connector for the Pan servo motor on a head. For pin-out
information see Servo motor connector on page 30.
2. PROG serial connector for connection to a controller using a Serial
RS232 connection (as an alternative to an Ethernet or DataLink
connection), and for updating the firmware in the Ulti-box. For
pin-out information see Program serial connector on page 30.
1 3 4 5 62
7 8 9 10 11
Page 33
Bolt Junior Quick Start Guide
29
3. POWER DC input for the Ulti-box and its attached devices. The
standard unit uses a power input of 24-36 Volts. The high-power
variant (marked HV, for High Voltage) uses 24-48 Volts. For pin-out
information see Power connector on page 31.
4. CAM ACC Camera Accessory input/output connector. It has pins for
three stepper motors, two serial lens controls, two trigger in
controls, and two trigger out controls. For pin-out information see
Camera Accessory connector on page 31.
5. DATA DataLink In (Up Link) connector for controlling the Ulti-box
and its attached devices using a DataLink connection, as an
alternative to an Ethernet or Serial RS232 connection. You connect
this to a device that is further up the DataLink daisy-chain, such as
one of the following:
The DATA OUT (or DOWN LINK) connector on a controller
such as the MSA-20 Handwheels or Large Format Panel (LFP).
The RIG/HEAD connector on an RT-14 interface box which is
in turn connected to a PC running Flair Motion Control
Software.
Note that because there is no DataLink Out connector on the
Ulti-box, the Ulti-box must be connected at the end of the DataLink
daisy-chain rather than the middle. For pin-out information see
Data In connector on page 32.
6. ETHERNET RJ45 connector for controlling the Ulti-box and its
connected devices from a Flair PC. This Ethernet port is rated at 100
Mbits/sec but can operate at lower speeds of 10 Mbits/sec or less.
7, 8. ZOOM, FOCUS connectors for external servo Lens Control Motors
(LCMs) mounted on the camera platform. For pin-out information
see Servo motor connector on page 30.
9. TILT connector for a Tilt servo motor on a head. For pin-out
information see Servo motor connector on page 30.
10, 11. AUX-1, AUX-2 connectors for control of auxiliary servo motors.
For pin-out information see Servo motor connector on page 30.
Page 34
Bolt Junior Quick Start Guide
30
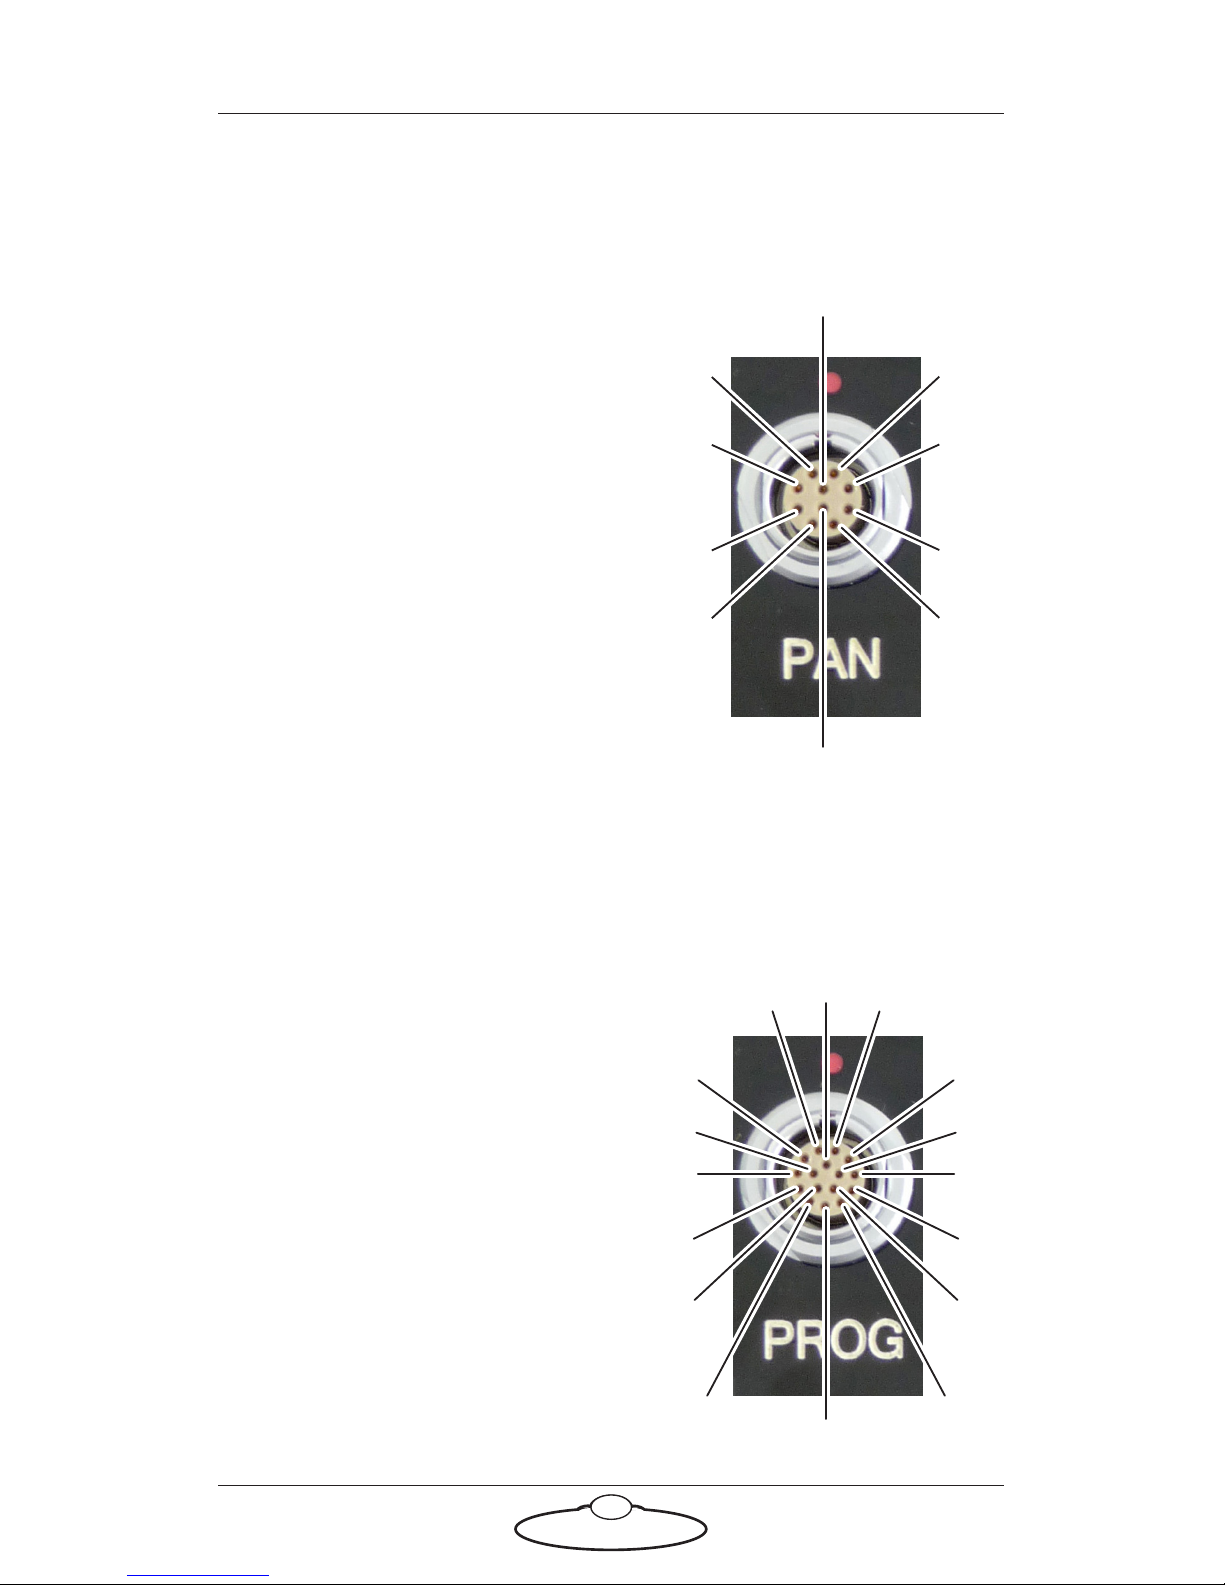
Ulti-box connector pin-out information
Servo motor connector
This type of connector is used for six
servo motor connectors on the Ulti-box:
Pan, Zoom, Focus, Tilt, Aux-1, Aux-2.
1. DATUM
2. A+
3. B+
4. Z+
5. N/C
6. MOTOR_B
7. MOTOR_A
8. LIMIT
9. +5V
10. GND
Program serial connector
Serial connector for connection to a controller using a Serial RS232
connection, and for updating the firmware in the Ulti-box.
1. SerialTxA
2. SerialRxA
3. +5V
4. FGPIO
5. DSP_TRSTN
6. TCK
7. TMS
8. DSP_TDI
9. DSP_TDO
10. DSP_EMU0
11. DSP_EMU1
12. FPGA_TDI
13. FPGA_TDO
14. BOOT_SEL
15. +3.3V
16. GND
2
1
4
3
7
8
5
6
9
10
1
2
3
4
5
7
15
8
9
10
11
13
6
16
12
14
Page 35
Bolt Junior Quick Start Guide
31
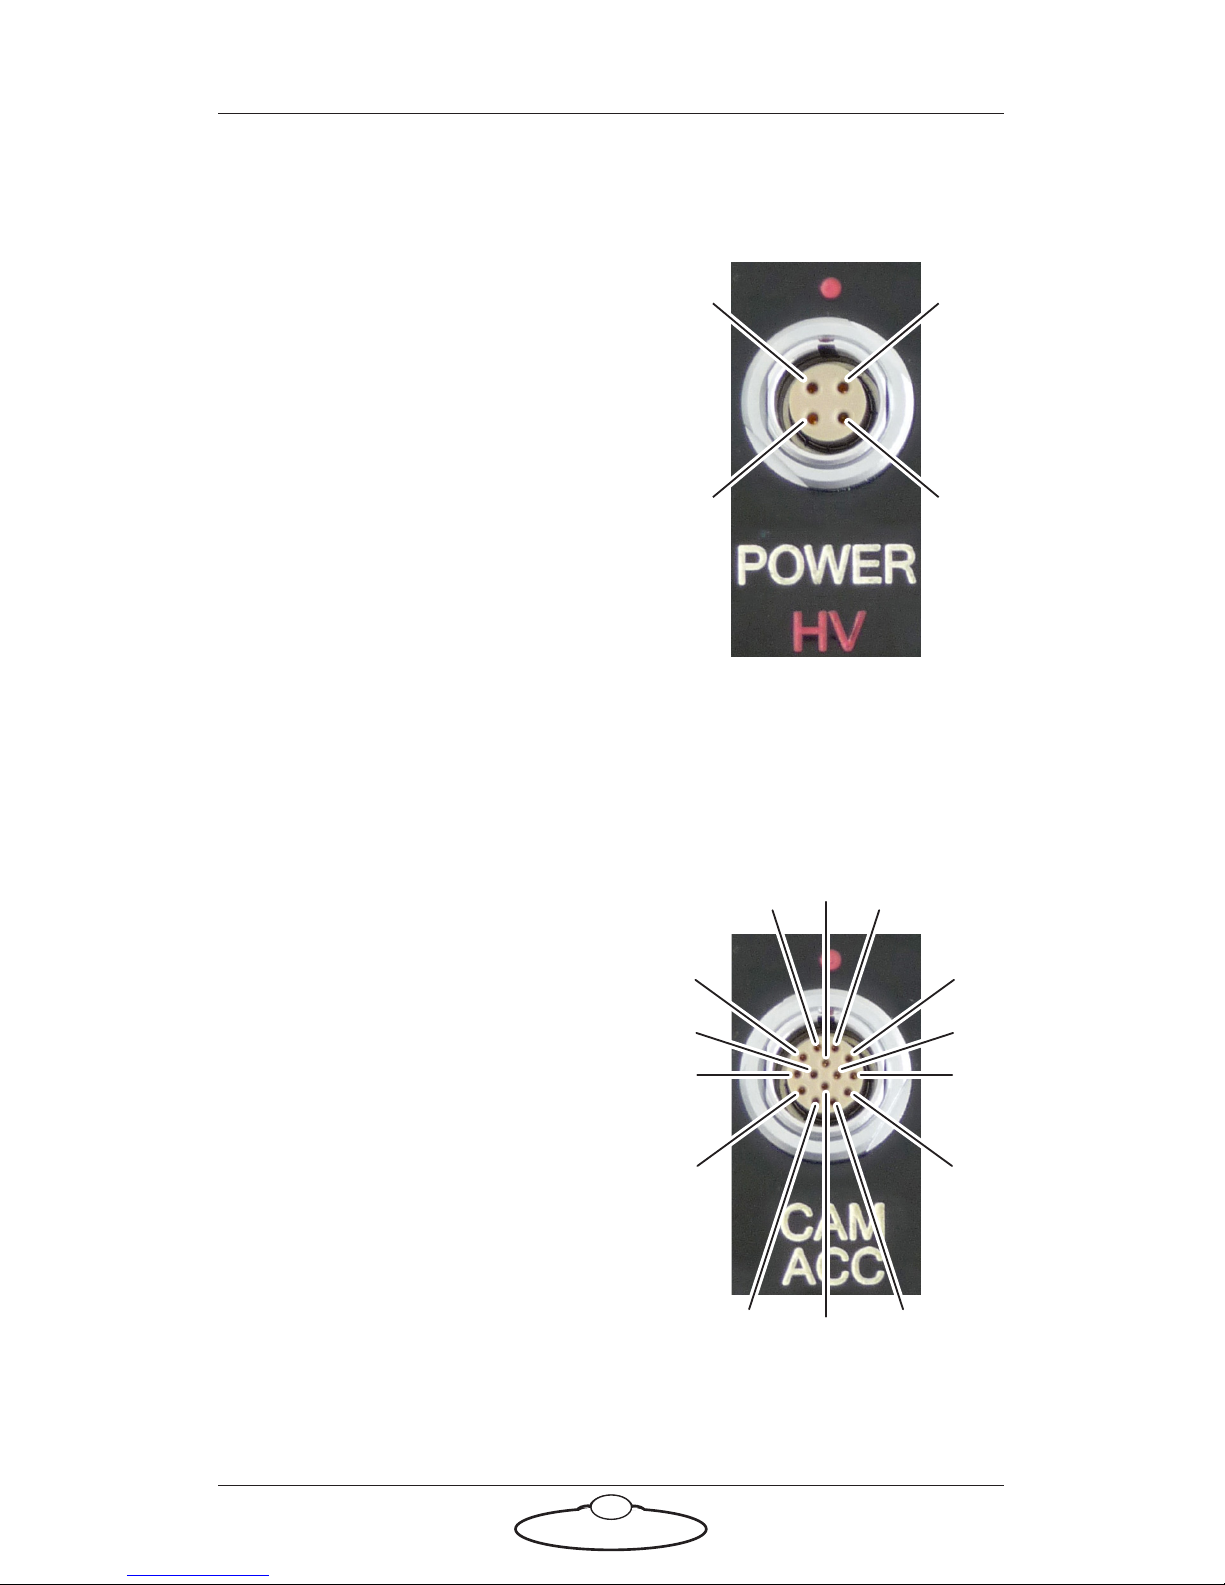
Power connector
The power input connector for the Ulti-box. For usage see page 29.
1. GND
2. GND
3. +35V
4. +35V
Camera Accessory connector
This is a multi-purpose camera accessory connector with connections for
three stepper motors, two serial lens controls, two trigger in controls, and
two trigger out controls.
1. Step1
2. Gp2In (Trigger In 2)
3. Step2
4. SerialTxB serial lens control
5. Step3
6. SerialRxB serial lens control
7. Dir3
8. GND
9. +5V
10. Gp1In (Trigger In 1)
11. Dir1
12. Dir2
13. Gp2Out (Trigger Out 2)
14. Gp1Out (Trigger Out 1)
3
4
2
1
1
2
3
4
5
6
7
8
9
10
11
12
13
14
Page 36
Bolt Junior Quick Start Guide
32
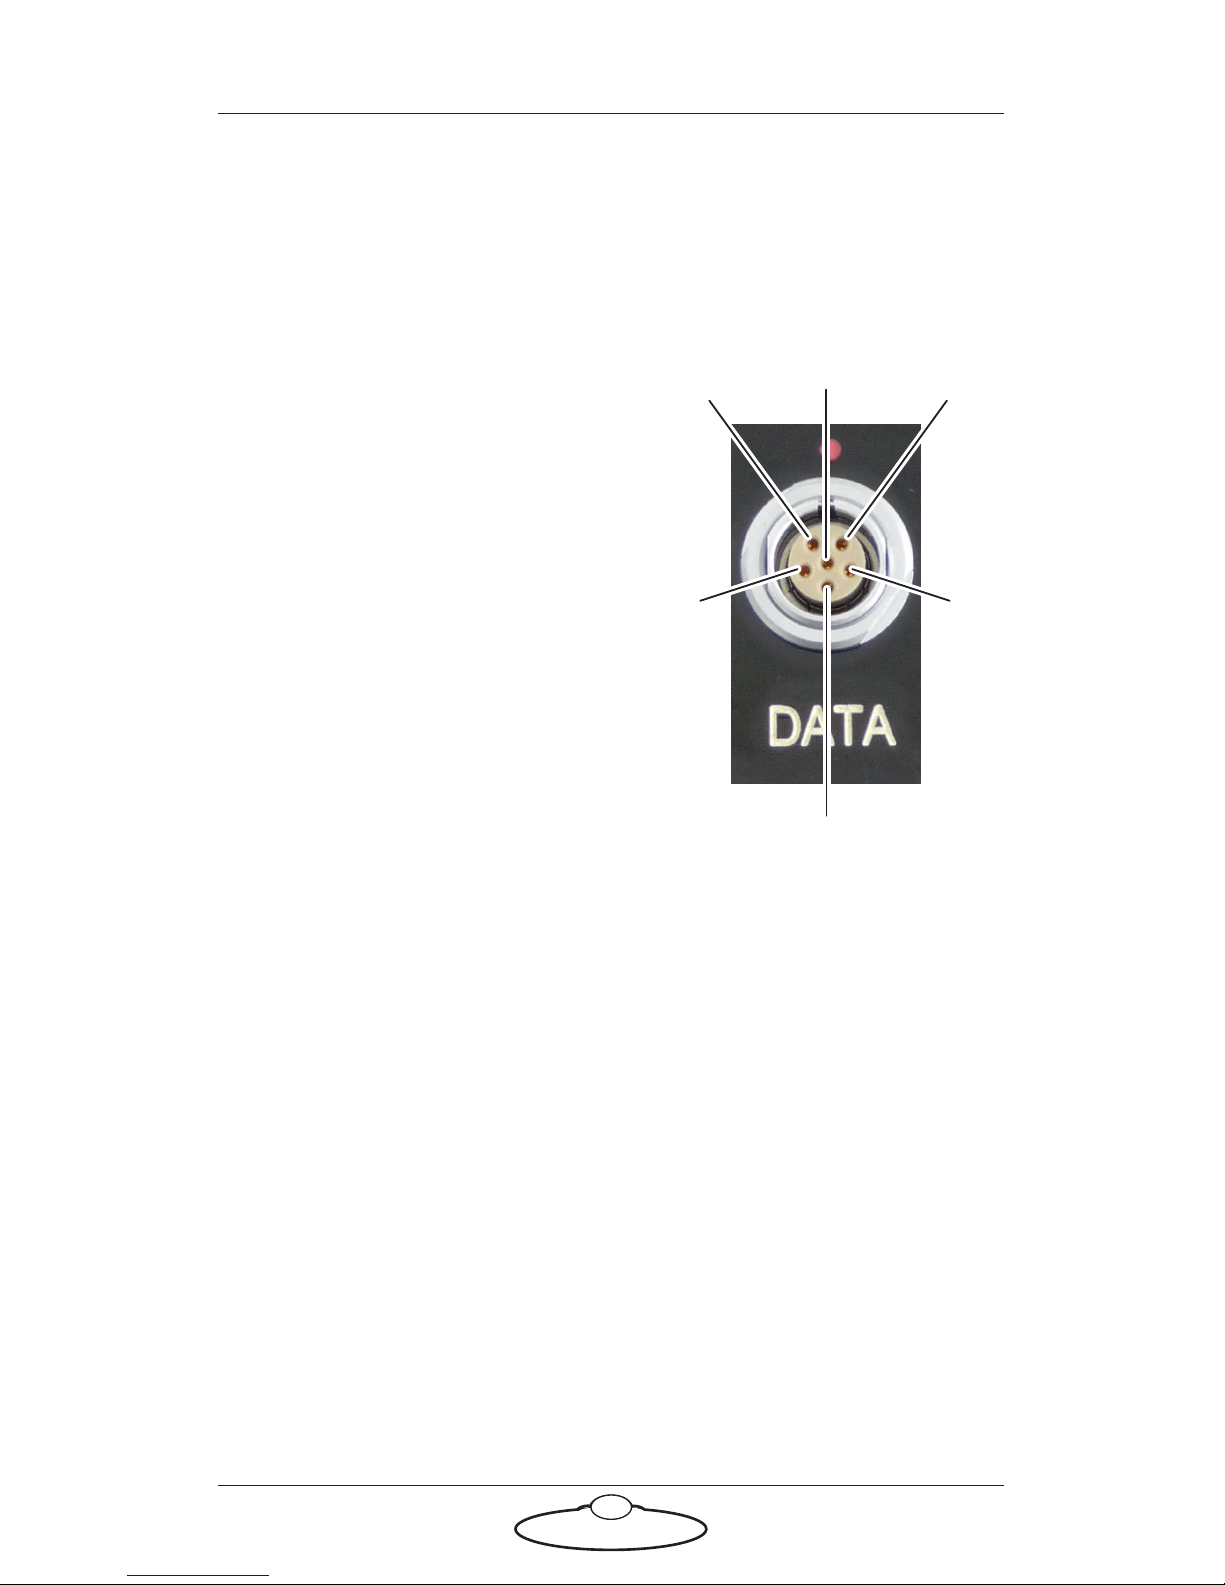
Data In connector
This is a DataLink In connector for connection to a controller using a
DataLink connection. DataLink In (Up Link) connector for connection to
a DataLink device higher up in the DataLink daisy-chain. For usage see.
page 29.
1. Watchdog–
2. Link1Out–
3. Link1Out+
4. Link1In–
5. Link1In+
6. Watchdog+
5
4
1
2
3
6
Page 37
Bolt Junior Quick Start Guide
33
Notes
Page 38
Bolt Junior Quick Start Guide
34
Bolt Junior Quick Start GuideBolt JuniorQuick Start Guide
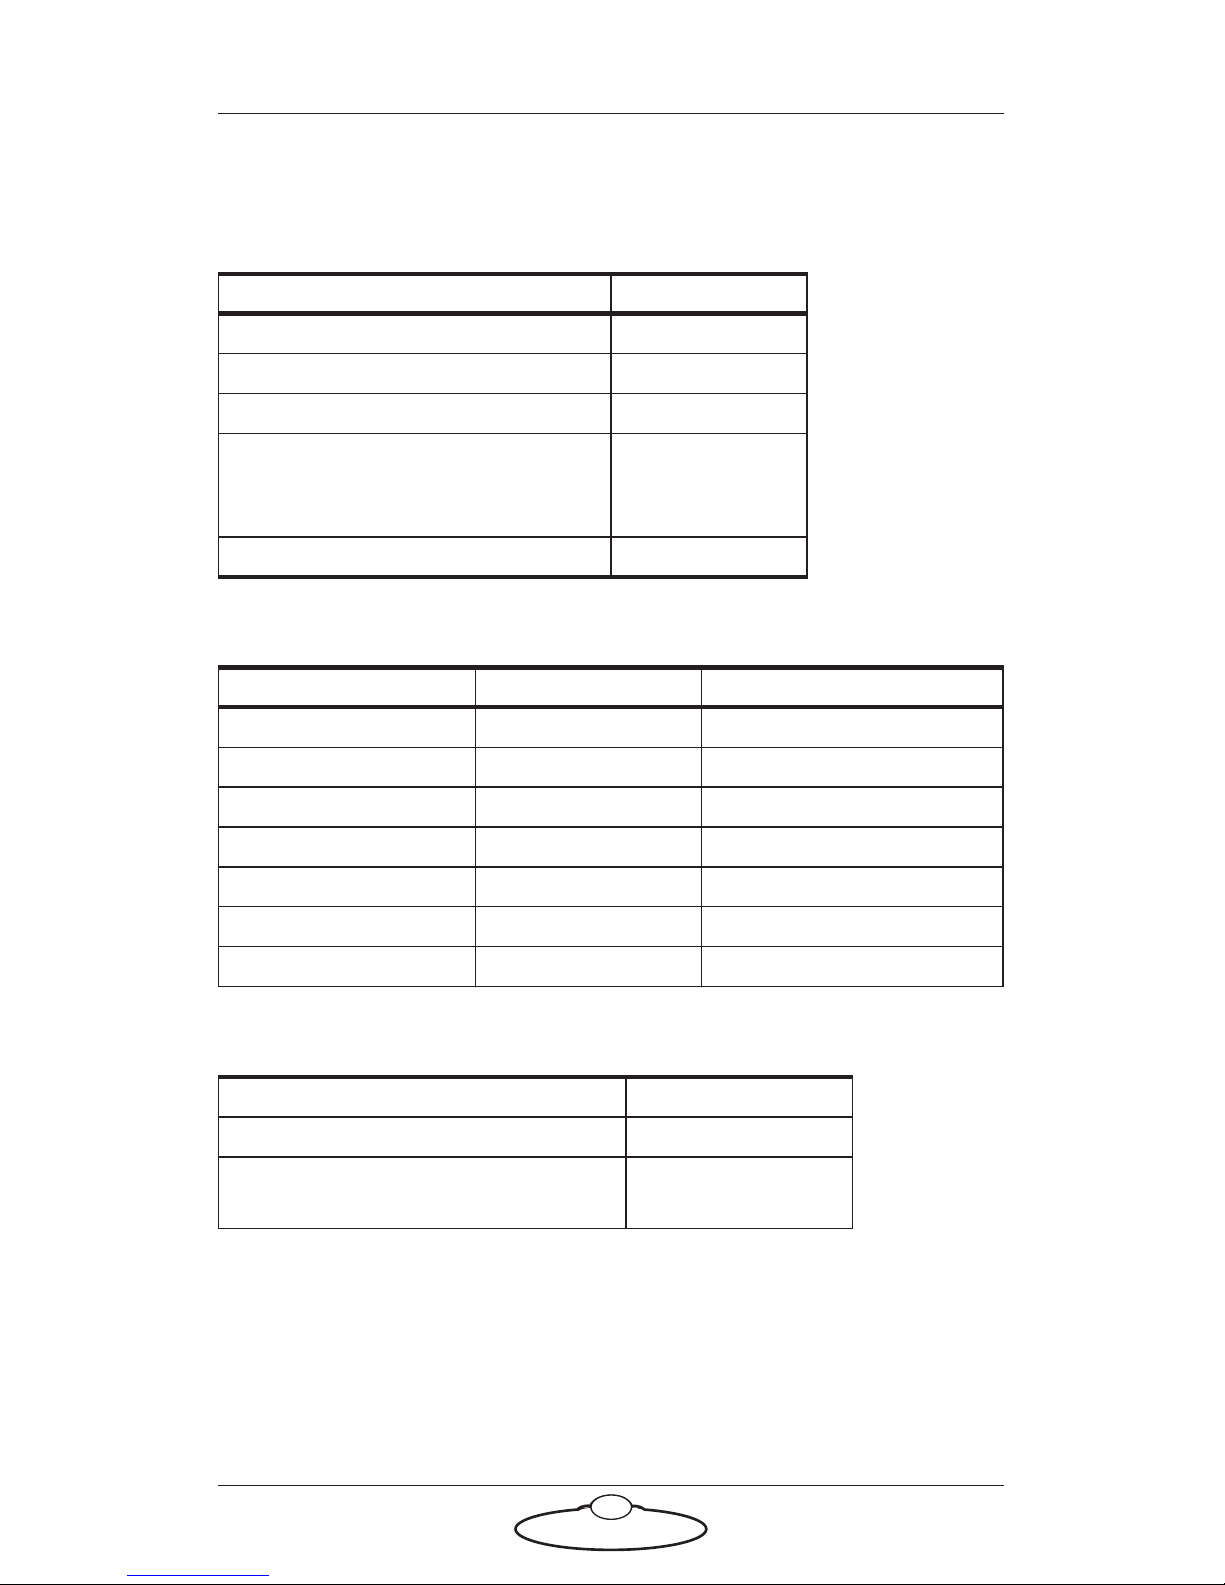
Appendix 3 Specifications
Rig Weights
Rig Performance
Operating Envelope
Temperature range: 0-45 °C (32-113 °F)
Humidity tolerance: 0% to 85% relative humidity, non-condensing
Power requirements: 3 x 400 Volt, 16 Amps, 50-60 Hz with Earth
(Ground) connection.
Optional power generator requirements: 10 kVA
Dimensions Bolt Junior
Weight excluding Base 114kg
Weight - Base 180kg
Power Supply Unit 50kg (110.2lbs)
Weight - anchor weights for track
(when track is not bolted to the
ground)
100kg on each
corner
Maximum camera payload 15kg (33lbs)
Axis Travel Max Speed
Rotate (Axis 1) ±180° 400°/ Second
Lift (Axis 2) +147.5° / -130° 390°/ Second
Arm (Axis 3) ±145° 400°/ Second
Pan (Axis 4) ±270° 540°/ Second
Tilt (Axis 5) +140° / -115° 475°/ Second
Roll (Axis 6) ±270° 260°/ Second
Track (Axis 7) Unlimited 2.9 m/ Second
Maximum Height (From Ground) 2.2M / 7’ 26”
Lowest Position 0M / 0’
Maximum reach (from rotate
centre)
1.2M / 3’11”
Page 39
Bolt Junior Quick Start Guide
35
Notes
Page 40
Mark Roberts Motion Control Ltd.
Unit 3, South East Studios, Blindley Heath, Surrey RH7 6JP
United Kingdom
Telephone: +44 (0) 1342 838000
[email protected]
www.mrmoco.com
 Loading...