

Page 1
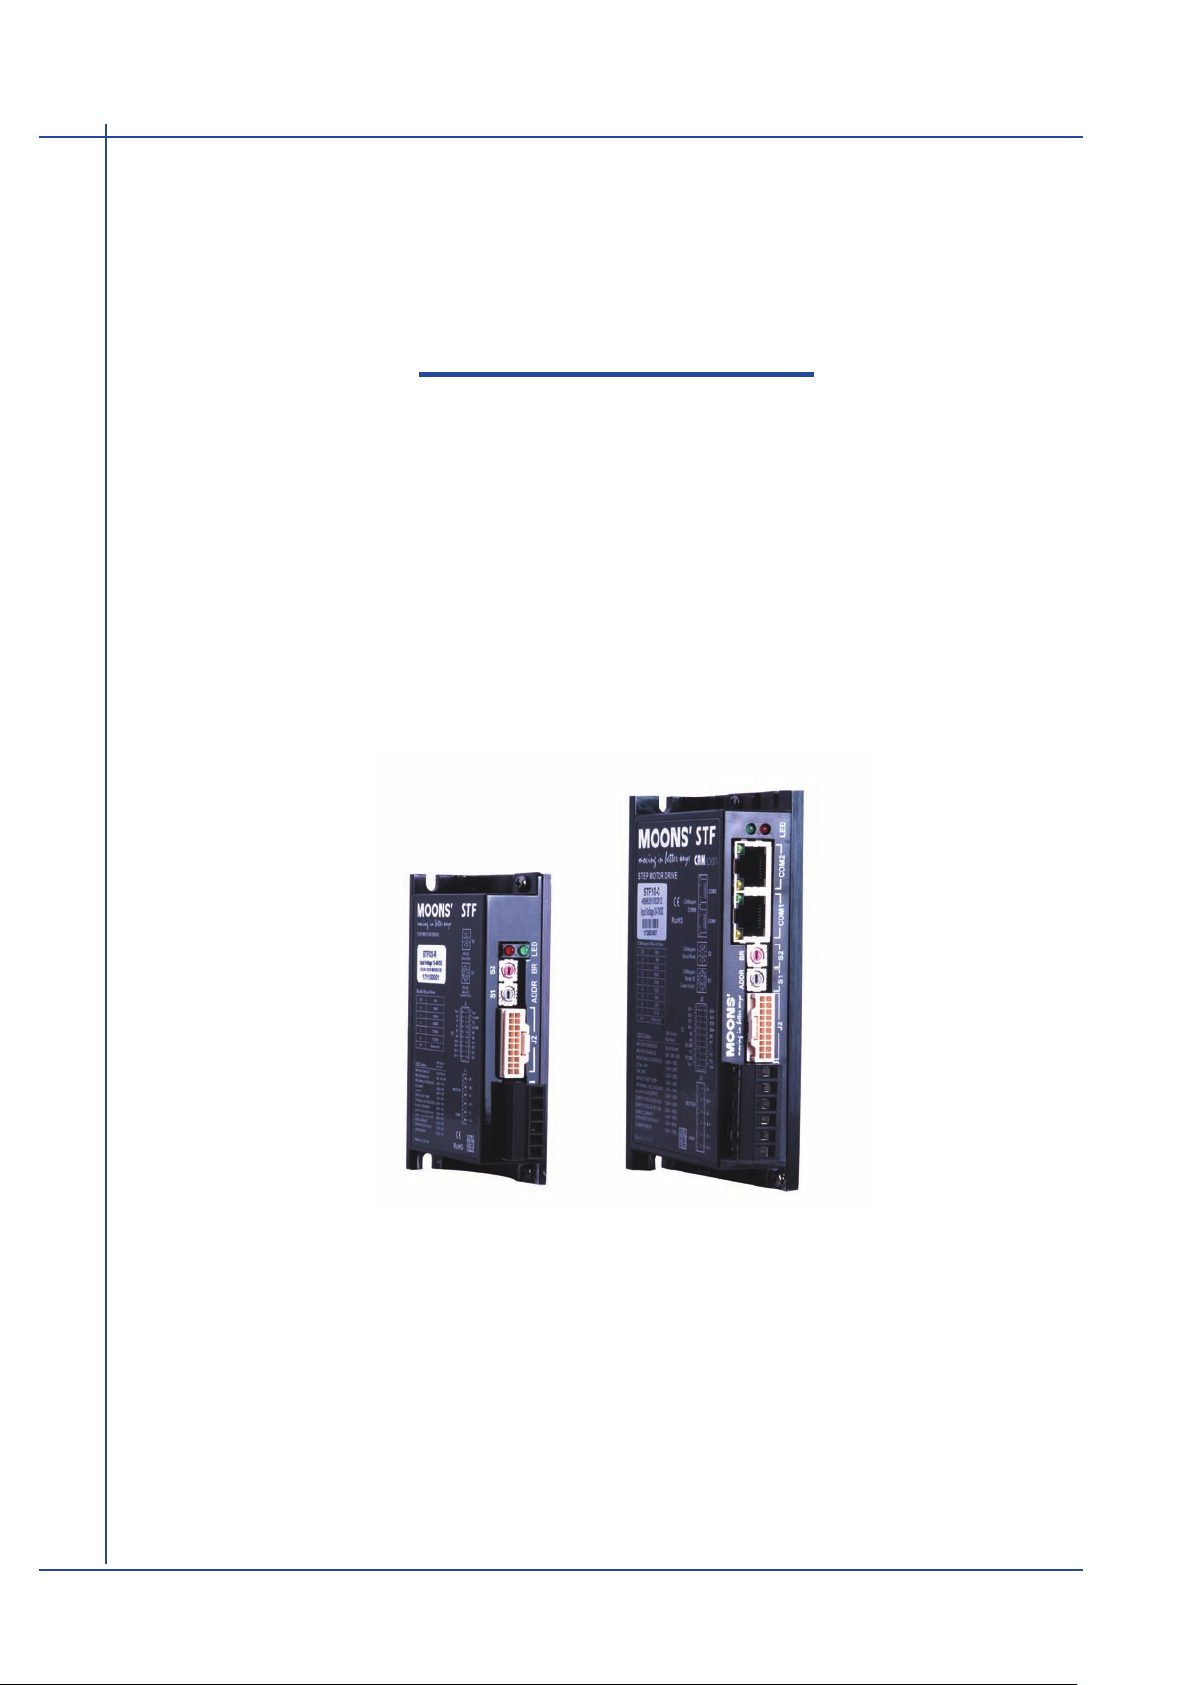
STF-R/C
Stepper Motor Drive
Hardware Manual
STF03-R STF05-R
STF06-R STF10-R
STF03-C STF05-C
STF06-C STF10-C
SHANGHAI AMP & MOONS’AUTOMATION CO.,LTD.
Rev. 1.0
11/08/2017
Page 2
STF-R/C Hardware Manual
Contents
1 Introduction ..................................................................................................3
1.1 Features .............................................................................................3
1.2 Block Diagram ...................................................................................4
1.3 Safety Instructions .............................................................................6
2 Getting Started ............................................................................................7
2.1 Installing Software .............................................................................8
2.2 Connecting communication (-R model) .............................................9
2.3 Connecting communication (-C model) ...........................................11
2.4 Setting bus address and baud rate ..................................................12
2.4.1 RS-485 address and baud rate settings(-R model) ............12
2.4.2
CANopen address and baud rate settings(-C model)
..........13
2.5 Connecting the Power Supply .........................................................14
2.6 Choosing A Power Supply ...............................................................15
2.6.1 Voltage ...............................................................................15
2.6.2 Current ................................................................................15
2.7 Connecting the motor ......................................................................16
3 Inputs and Outputs ....................................................................................16
3.1 Digital Inputs ....................................................................................17
3.1.1 X1, X2, X3, X4 digital input signal ......................................17
3.1.2 X5, X6, X7, X8 digital input signal ......................................18
3.2 Digital Outputs .................................................................................19
3.2.1 Y1, Y2, Y3 Digital Outputs ..................................................19
3.2.2 Y4 Digital Output ................................................................20
4 Mounting the Drive ....................................................................................21
5 Reference Materials ..................................................................................22
5.1 Drive Mechanical Outlines ...............................................................22
5.2 Technical Specications ...................................................................23
5.3 Recommended Motor ......................................................................24
5.4 Torque Curves .................................................................................27
5.5 Numbering System ..........................................................................30
5.6 Ordering Information ........................................................................30
5.7 Alarm Code ......................................................................................30
6 Accessories (Sold Separately) ..................................................................31
7 Contacting MOONS’ ..................................................................................32
Rev. 1.0
11/08/2017
2
400-820-9661
Page 3
STF-R/C Hardware Manual
1 Introduction
Thank you for selecting the MOONS’STF series stepper drive. The STF series are high
performance fieldbus control stepper drive which also integrates with built-in motion controller. The
drives can be controlled by SCL, Modbus/RTU or CANopen in real time. Motion profiles can also
be programmed and stored in drives (Q Program) and then be triggered by SCL, Modbus/RTU or
CANopen commands. The drives
1.1 Features
support RS-485/422 or CANopen communication.
• Programmable, filed bus controlled stepper motor drive in compact package
• Operating DC voltage range:
STF03 12-48V
STF05 24-48V
STF06 12-48V
STF10
• Control Mode
SCL
Q program
Modbus/RTU (-R model only)
CANopen(-C model only)
• Communication
-R: Dual port RS-485/
-C: Dual port CANopen, RS-232 included
•
STF03 output current: max 3A/phase (peak-of-sine)
• STF05 output current: max 5A/phase (peak-of-sine)
• STF06 output current: max 6A/phase (peak-of-sine)
• STF10 output current: max 10A/phase (peak-of-sine)
• I/O
8 optically isolated digital inputs, 5-24VDC high level voltage
4 optically isolated digital outputs, max30V/100mA
24-70V
* Serial Communication Command
* Stand-Alone operation mode
* Compliant with CiA301 and CiA402 standard
422
400-820-9661
3
Rev. 1.0
11/08/2017
Page 4
STF-R/C Hardware Manual
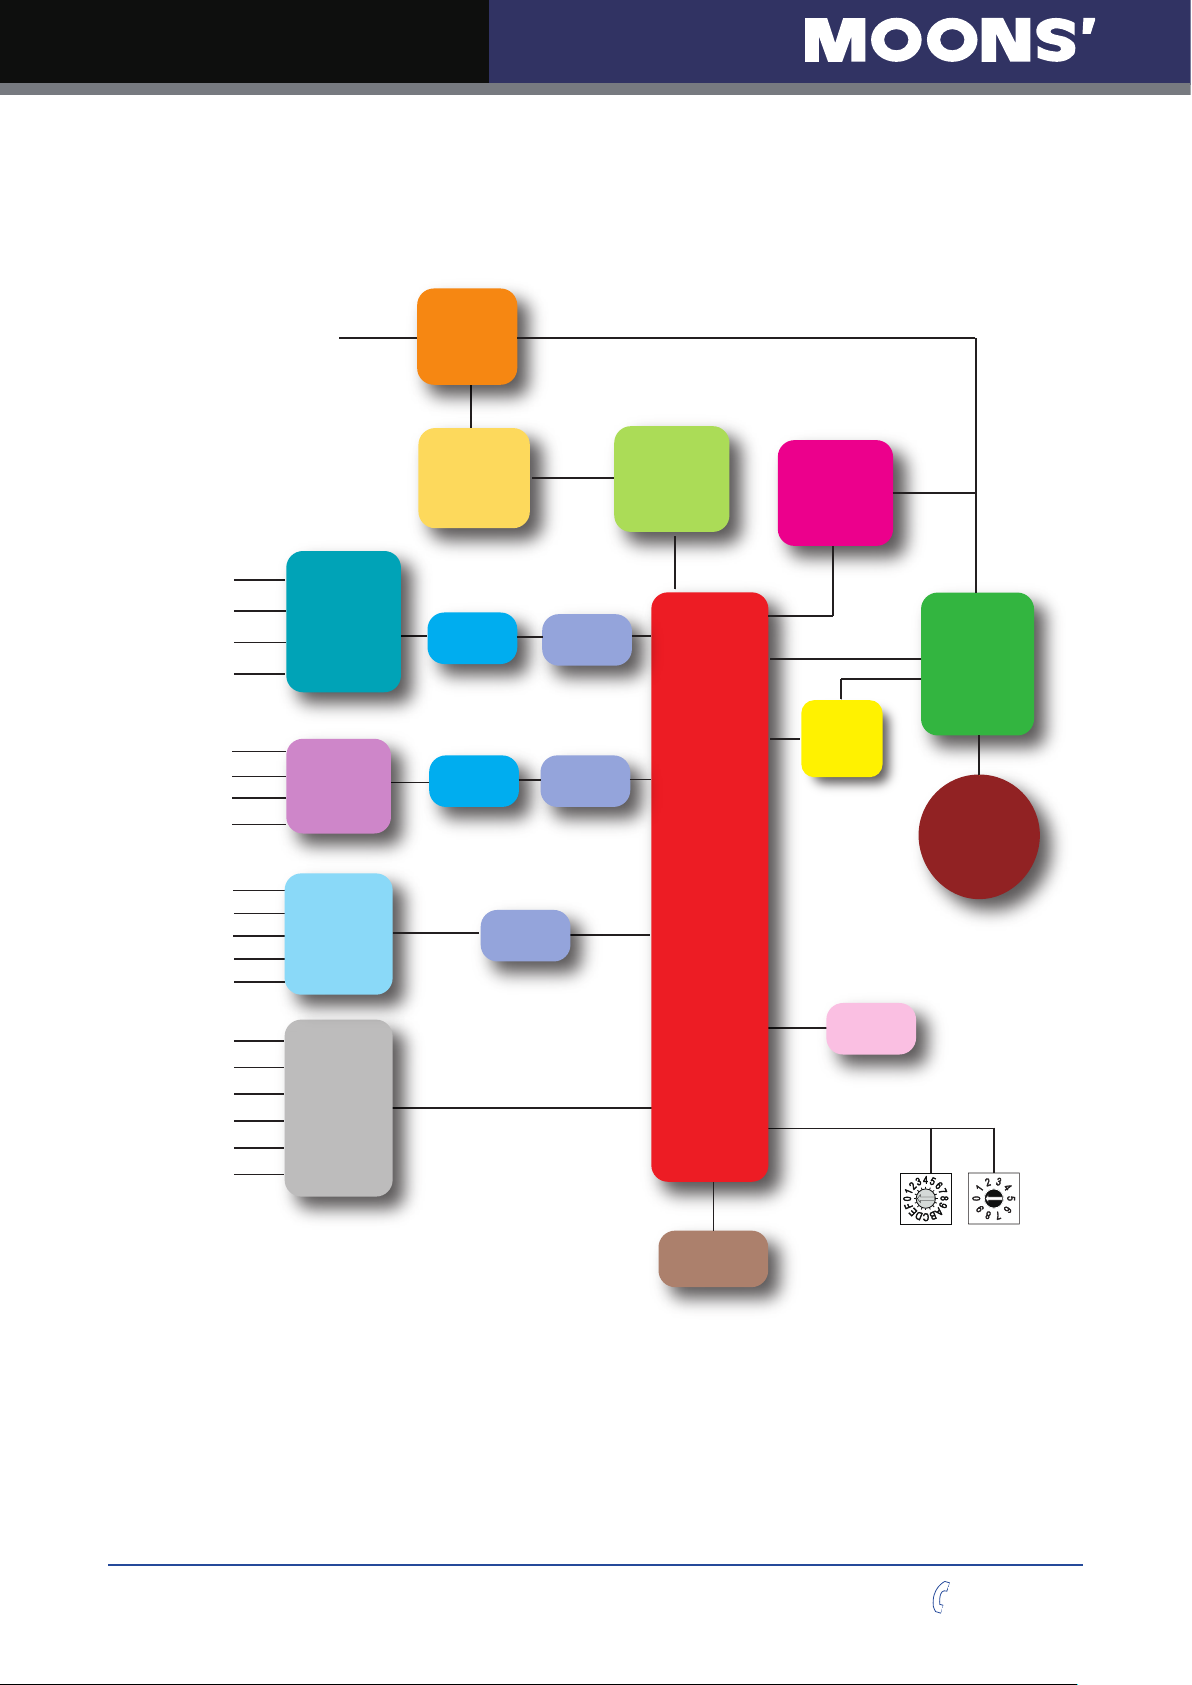
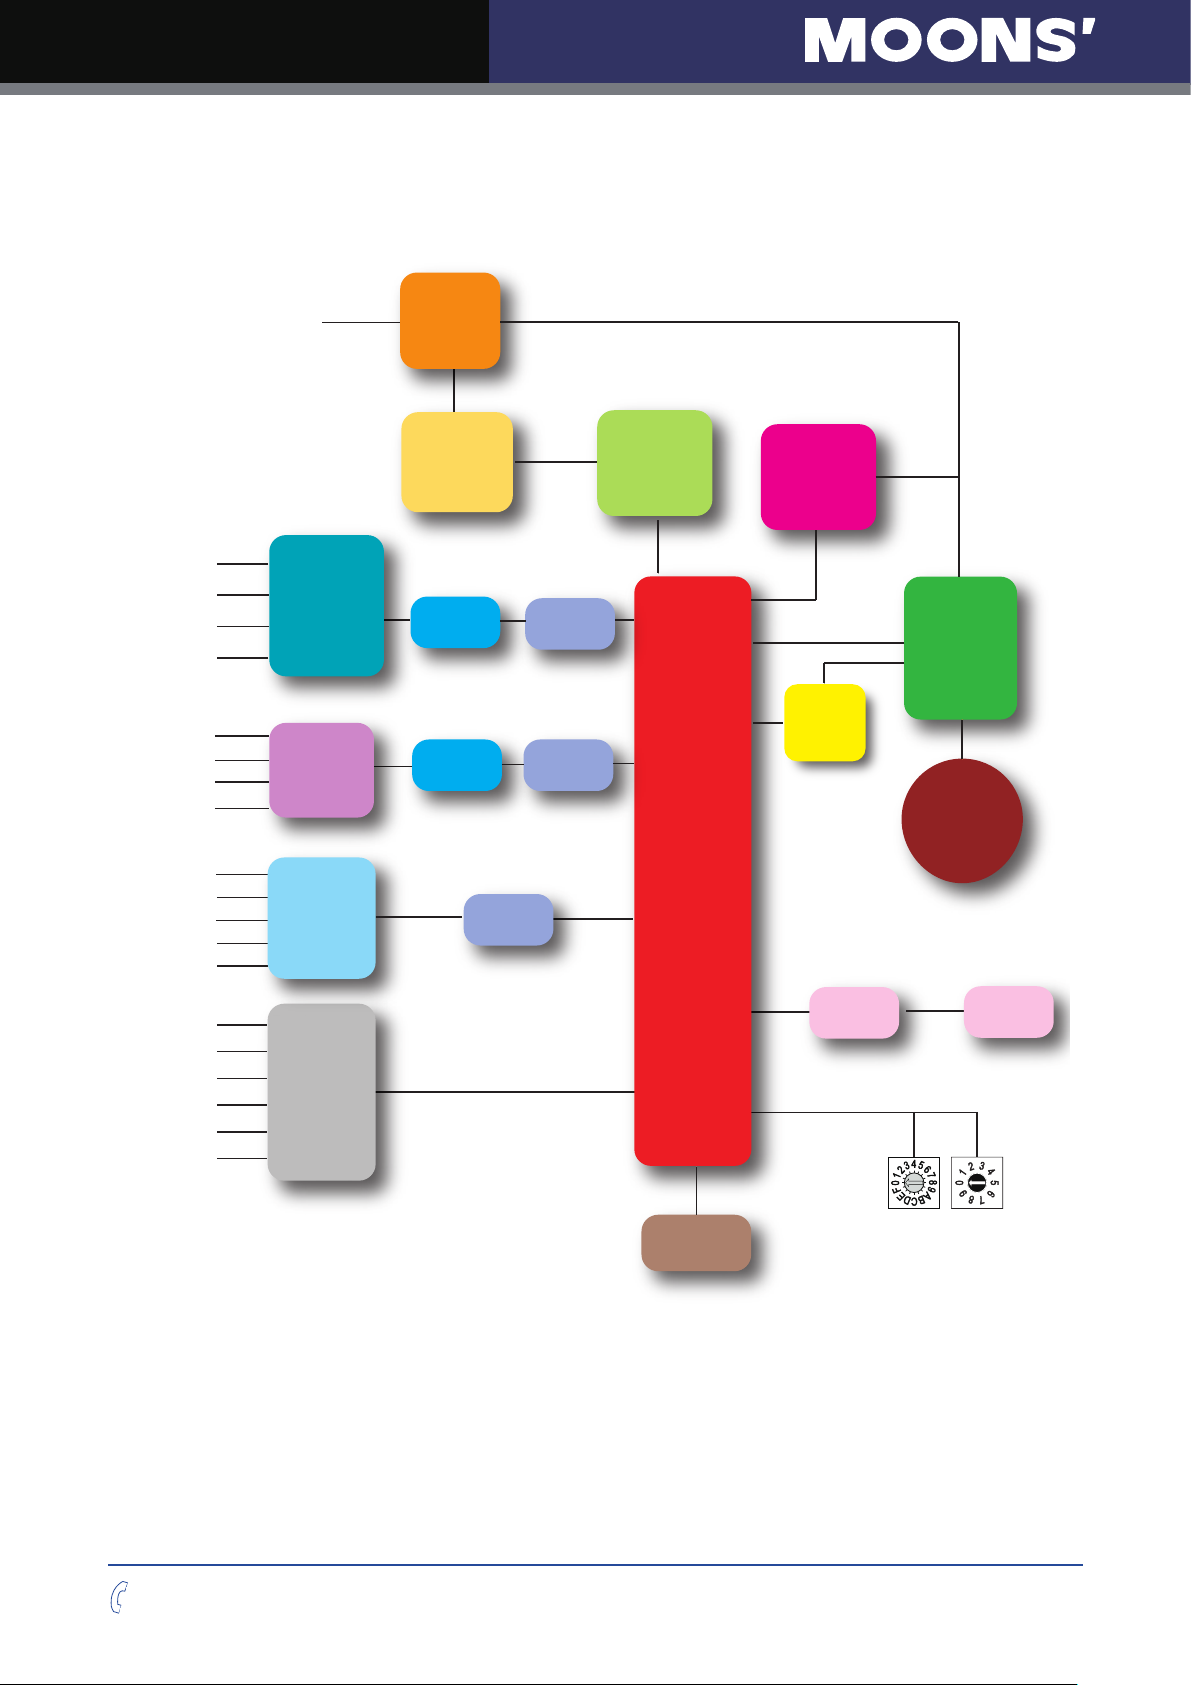
1.2 Block Diagram
STF-R Block Diagram
Power Supply
STF03 12-48VDC
STF05 24-48VDC
STF06 12-48VDC
STF10 24-70VDC
X1+
X1-
X2+
X2-
X3+
X3-
X4+
X4-
X5
X6
X7
X8
XCOM
High
Speed
Input
Optical
Isolation
Input
Optical
Isolation
Single
Ended
Input
Isolation
EMC
Filter
DC Input
Power
Converter
Digital
Filter
Digital
Filter
Software
Filter
Software
Filter
Software
Filter
Internal
Logic
Supply
DSP
Voltage
Temp.
Det.
Mosfet
PWM
Power
Amplifier
Over
Current
Det.
Motor
YCOM
Rev. 1.0
11/08/2017
Y1
Y2
Y3
Y4+
Y4-
Output
Optical
Isolation
RS-485
RS-485
address
S1
LED
4
400-820-9661
RS-485
baud rate
S2
Page 5
STF-R/C Hardware Manual
STF-C Block Diagram
Power Supply
STF03 12-48VDC
STF05 24-48VDC
STF06 12-48VDC
STF10 24-70VDC
X1+
X1-
X2+
X2-
X3+
X3-
X4+
X4-
X5
X6
X7
X8
XCOM
High
Speed
Input
Optical
Isolation
Input
Optical
Isolation
Single
Ended
Input
Isolation
EMC
Filter
DC Input
Power
Converter
Digital
Filter
Digital
Filter
Software
Filter
Software
Filter
Software
Filter
Internal
Logic
Supply
DSP
Voltage
Temp.
Det.
Mosfet
PWM
Power
Amplifier
Over
Current
Det.
Motor
Y1
Y2
Y3
YCOM
Y4+
Y4-
400-820-9661
Output
Optical
Isolation
ARM
CANopen
Node ID
S1
LED
5
CANopen
CANopen
Baud rate
S2
Rev. 1.0
11/08/2017
Page 6
STF-R/C Hardware Manual
1.3 Safety Instructions
Only qualified personnel should transport, assemble, install, operate, or maintain this equipment.
Properly qualified personnel are persons who are familiar with the transport, assembly, installation,
operation, and maintenance of motors, and who meet the appropriate qualifications for their jobs.
To minimize the risk of potential safety problems, all applicable local and national codes regulating
the installation and operation of equipment should be followed.
to area and it is the responsibility of the operating personnel to determine which codes should be
followed, and to verify that the equipment, installation, and operation are in compliance with the
latest revision of these codes.
Equipment damage or serious injury to personnel can resu
codes and standards. MOONS
are suitable for a particular application, nor do they assume any responsibility for product design,
installation, or operation.
• Read all available documentation before assembly and operation. Incorrect handling of the
products referenced in this manual can result
All technical information concerning the installation requirements must be strictly adhered to.
’ does not guarantee the products described in this publication
in injury and damage to persons and machinery.
These codes may vary from area
lt from the failure to follow all applicable
It is vital to ensure that all system components are connected to earth ground. Electrical safety
•
is impossible without a low-resistance earth connection.
• This product contains electrostatically sensitive components that can be damaged by incorrect
handling. Follow qualified anti-static procedures before touching the product.
During operation keep all covers and cabinet doors shut to avoid any hazards that could
•
possibly cause severe damage to the product or personal health.
• During operation, the product may have components that are live or have hot surfaces.
• Never plug in or unplug the Integrated Motor while the system is live. The possibility of electric
arcing can cause damage.
Be alert to the potential for personal injury
practices emphasized with alert symbols. Safety notices in this manual provide important
information. Read and be familiar with these instructions before attempting installation, operation,
or maintenance. The purpose of this section is to alert users to the possi
associated with this equipment and the precautions necessary to reduce the risk of personal injury
and damage to equipment. Failure to observe these precautions could result in serious bodily
injury
, damage to the equipment, or operational difficulty.
. Follow recommended precautions and safe operating
ble safety hazards
Rev. 1.0
11/08/2017
6
400-820-9661
Page 7
STF-R/C Hardware Manual
2 Getting Started
The following items are needed:
• An appropriate power supply, see the section below entitled“Choose a Power Supply”for
help in choosing the right one.
• A compatible stepper motor, please see the section below entitled “Recommended Motor”
• A small flat blade screwdriver for tightening the connectors screw(included)
• A PC running Microsoft Windows XP / Vista / Windows 7/ Windows 8 / Windows 10(32-bit or
64-bit)operation system
•
Optional I/O cable (Sold seperately)
• Install STF Congurator software (Available from MOONS’website)
• -R model
A network cable is included in the package. It is used for connection with the next drive in the
RS-485 network. It can also be used for connection with PC for drive configuration.
• -C model
A RS-232 programming cable(included in the package)
A network cable is included in the packag
CANopen network.
TIP: When connecting the rst drive in the RS-485 or CANopen network with PC or controller. you
can cut the daisy chain cable or network cable into two: one half is used for connection with the
RS-485 or CANopen port on the PC or controller
termination resistor, which can be put at the end of the network.
e. It is used for connection with the next drive in the
, the other half can be used for connection with
400-820-9661
7
Rev. 1.0
11/08/2017
Page 8
STF-R/C Hardware Manual
2.1 Installing Software
• Download the STF Congurator Software from the MOONS’ website and install it.
• Launch the software by clicking Start-----Programs ----MOONS’
• Connect the drive to the PC using communication cable:
Connect the -R model drive to the RS-485 port of the PC using the network cable included in
the package
Connect the -C model drive to the RS-232 port of the PC using the RS-232 cable included in
the package
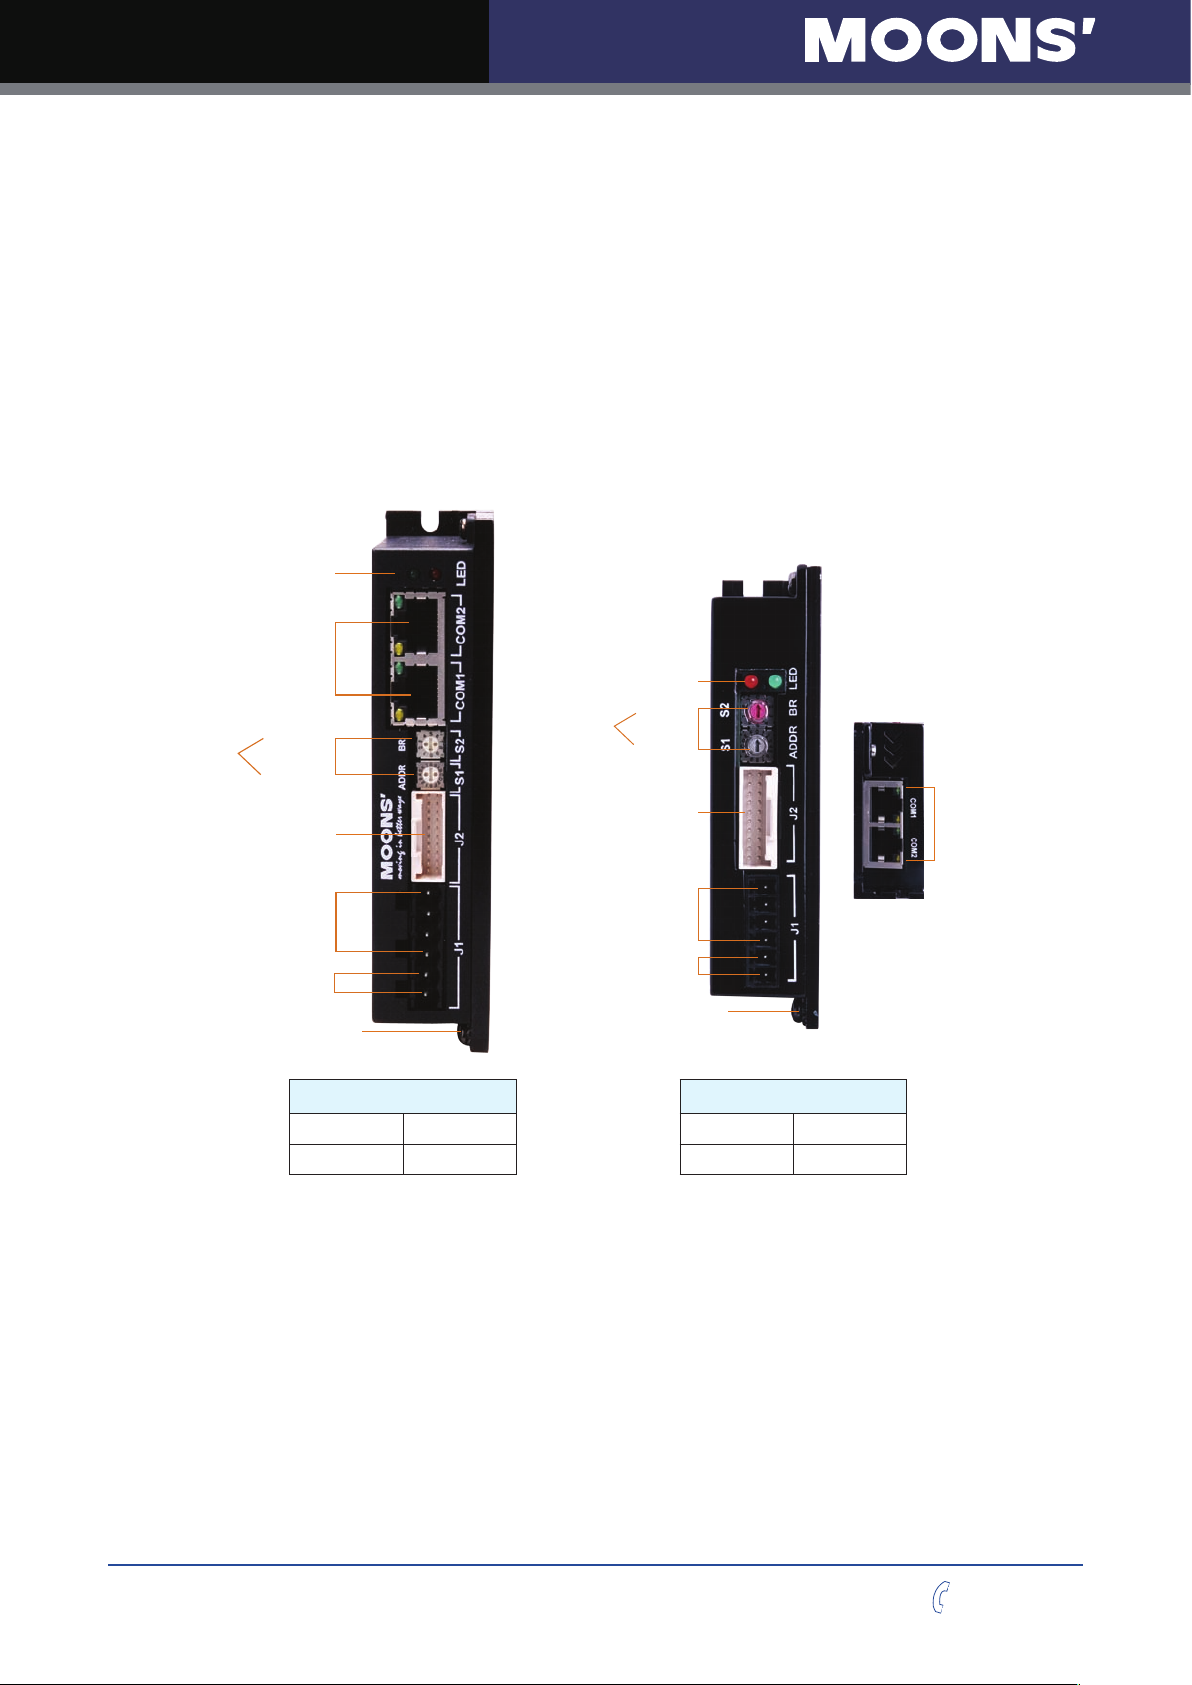
The connectors and other points of interest are illustrated below:
LED
RS-485 or CANopen
RS-485 or CANopen
Communication
Connector
Band Rate
Node ID
I/O Connector
Motor Connector
Power Connector
Ground Screws
LED
RS-485 or CANopen
Band Rate
Node ID
I/O Connector
Motor Connector
Power Connector
Ground Screws
Model Number Model Number
STF05-R STF05-C STF03-R STF03-C
STF10-R STF10-C STF06-R STF06-C
RS-485 or CANopen
Communication Connector
Rev. 1.0
11/08/2017
8
400-820-9661
Page 9
STF-R/C Hardware Manual
1 8
1 8
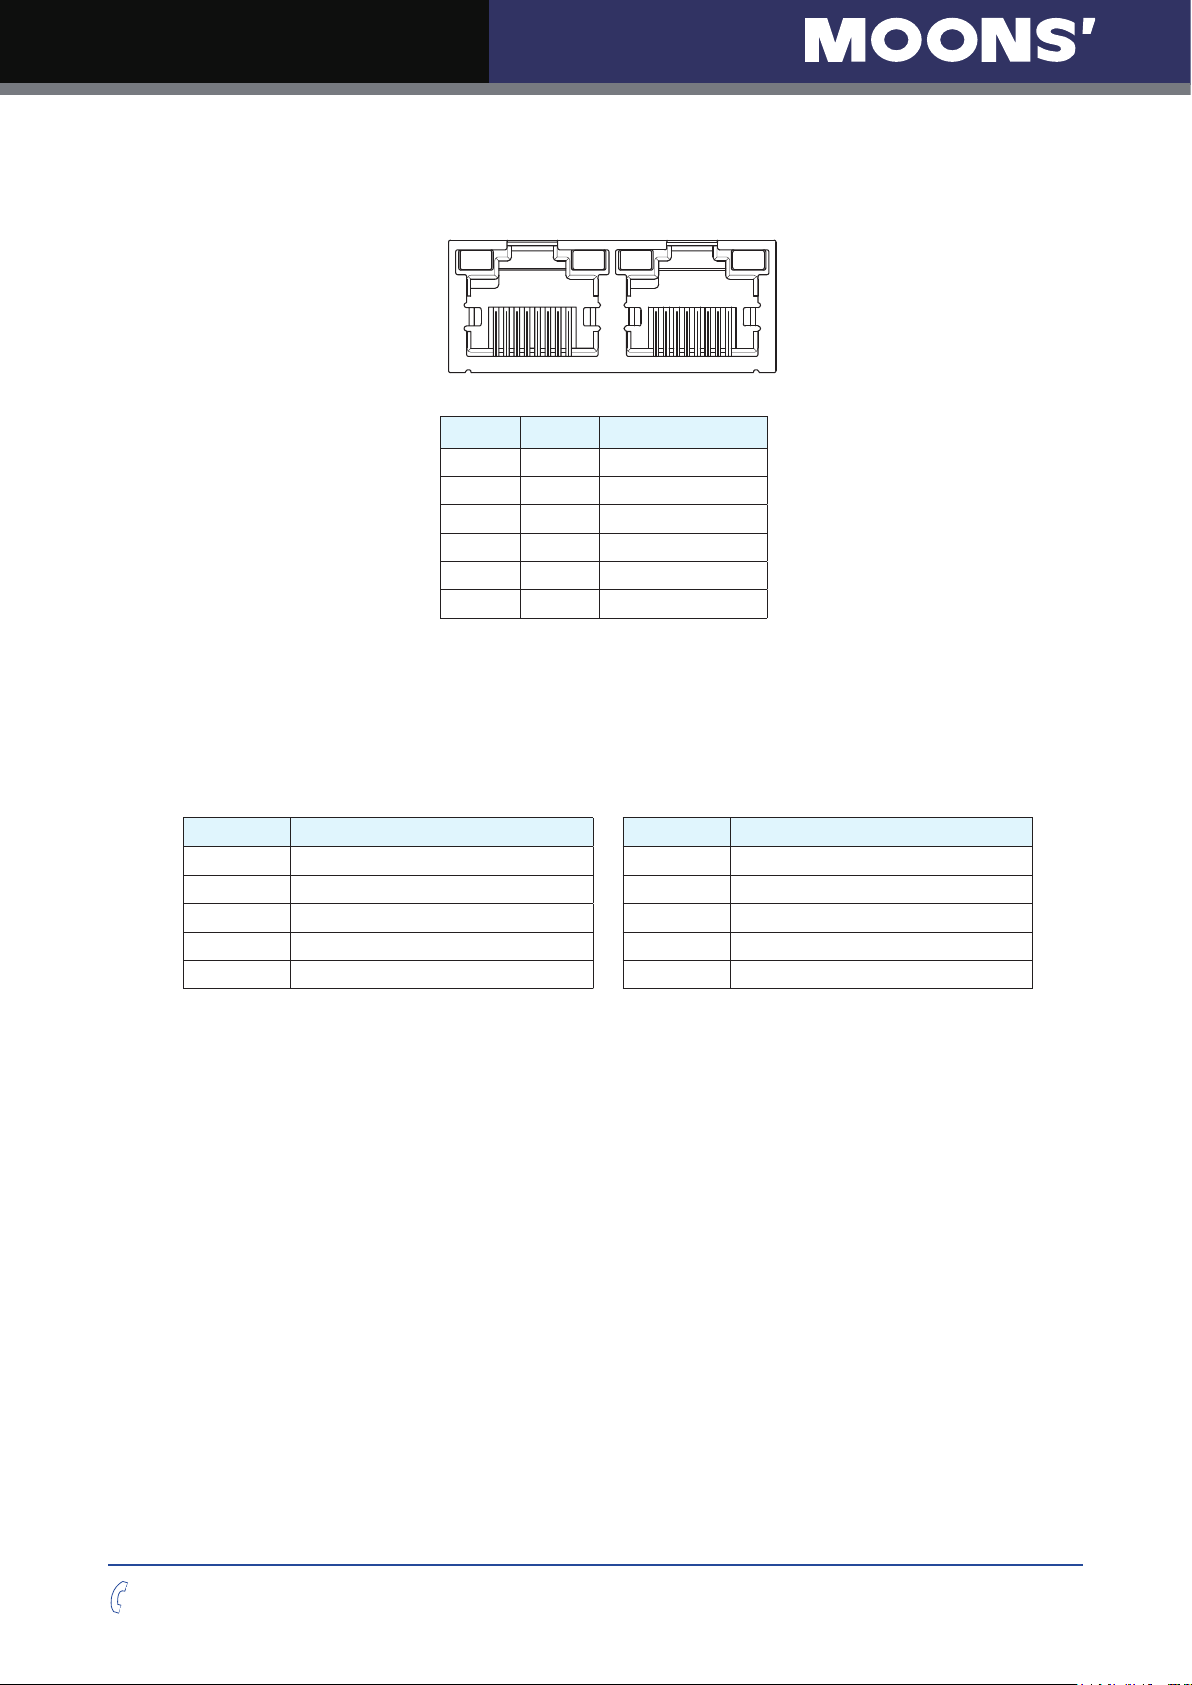
2.2 Connecting communication (-R model)
RS-485 Port
PIN Signal
1 RX+ ORN/WHT
2 RX- ORN
3 TX+ GRN/WHT
4.5 NC BLU, BLU/WHT
6 TX- GRN
7.8 GND BRN/WHT, BRN
Wire Color
Connection STF drive with PC using RS-485 communication
Before using STF congurator for –R drive conguration, please connect COM1 or COM2 on the
driver to host PC by network cable provided. Both 4 wire connection or 2 wire connection can be
used.
RS-485 four-wire connection: RS-485 two-wire connection:
Drive Connection
RX+ Connect to host’s TX+
RX- Connect to host’s TXTX+ Connect to host’s RX+
TX- Connect to host’s RXGND Connect to host’s GND
Drive Connection
RX+ Connect to host’s +
RX- Connect to host’s TX+ Connect to host’s +
TX- Connect to host’s GND Connect to host’s GND
NOTE: The RS-485 port on the drive is isolated from internal circuitry of the drive. So the
GND of each drive's RS-485 port must be connected together. The rst drive's GND of the
RS-485 port must be connected to the GND of RS-485 port on the host PC or controller.
400-820-9661
9
Rev. 1.0
11/08/2017
Page 10
STF-R/C Hardware Manual
RS-485 network connection
Multiple –R model drive network can be built via dual RS-485 communication port by network
cable provided.
RS-485 Four-wire Configuration
RS-485 four-wire system utilize separate transmit and receive wires. One pair of wires connect
the host’s transmit signals(TX+/TX-) to each drive’s RX+/RX- receive terminals. The other pair
connects the drive’s TX+/TX- terminals to the host’s receive signals. A logical ground terminal is
provided on each drive and can be used to keep all the drives at the same ground potential. The
rst drive’s logical GND of the RS-485 bus must connect to host’s ground.
Four-wire Connection
Connect the drive’s RX+ to the TX+ terminal of the host controller,and connect the drive’s RX- to
the TX- terminal of the host controller . Connect the drive’s TX+ to the RX+ terminal of the host
controller,and connect the drive’s TX- to the RX- terminal of the host controller .
Connect the drive’s GND and the host’s GND to a same ground.
NOTE: The RS-485 port on the drive is isolated from internal circuitry of the drive. So the
GND of each drive’s RS-485 port must be connected together. The rst drive’s GND of the
RS-485 port must be connected to the GND of RS-485 port on the host PC or controller.
RS-485 Tow-wire Configuration
In a two-wire system ,the data transmitting and receiving use a same cable. the host must stop
its transmitting before receiving data. That means the host must stop transmit data before drive
begins to answer a query which just come from the host, otherwise the host cannot receive
any data witch sent from a drive. There is a transmit delay parameter that can be adjusted to
compensate for a host that is slow to disable its transmitter. This adjustment can be set over the
network using the TD command,it also can be set by using the STF Congurator software. Users
can set a shorter transmit delay in a four-wire system.
Two-wire connection
The RX+ and TX+ of the drive connect to the host’s + in parallel. The RX- and TX- of the drive
connect to the host’s - in parallel. Connect the drive’s GND and the host’s GND to a same ground.
NOTE: The RS-485 port on the drive is isolated from internal circuitry of the drive. So the
GND of each drive’s RS-485 port must be connected together. The rst drive’s GND of the
RS-485 port must be connected to the GND of RS-485 port on the host PC or controller.
Rev. 1.0
11/08/2017
10
400-820-9661
Page 11
STF-R/C Hardware Manual
2.3 Connecting communication (-C model)
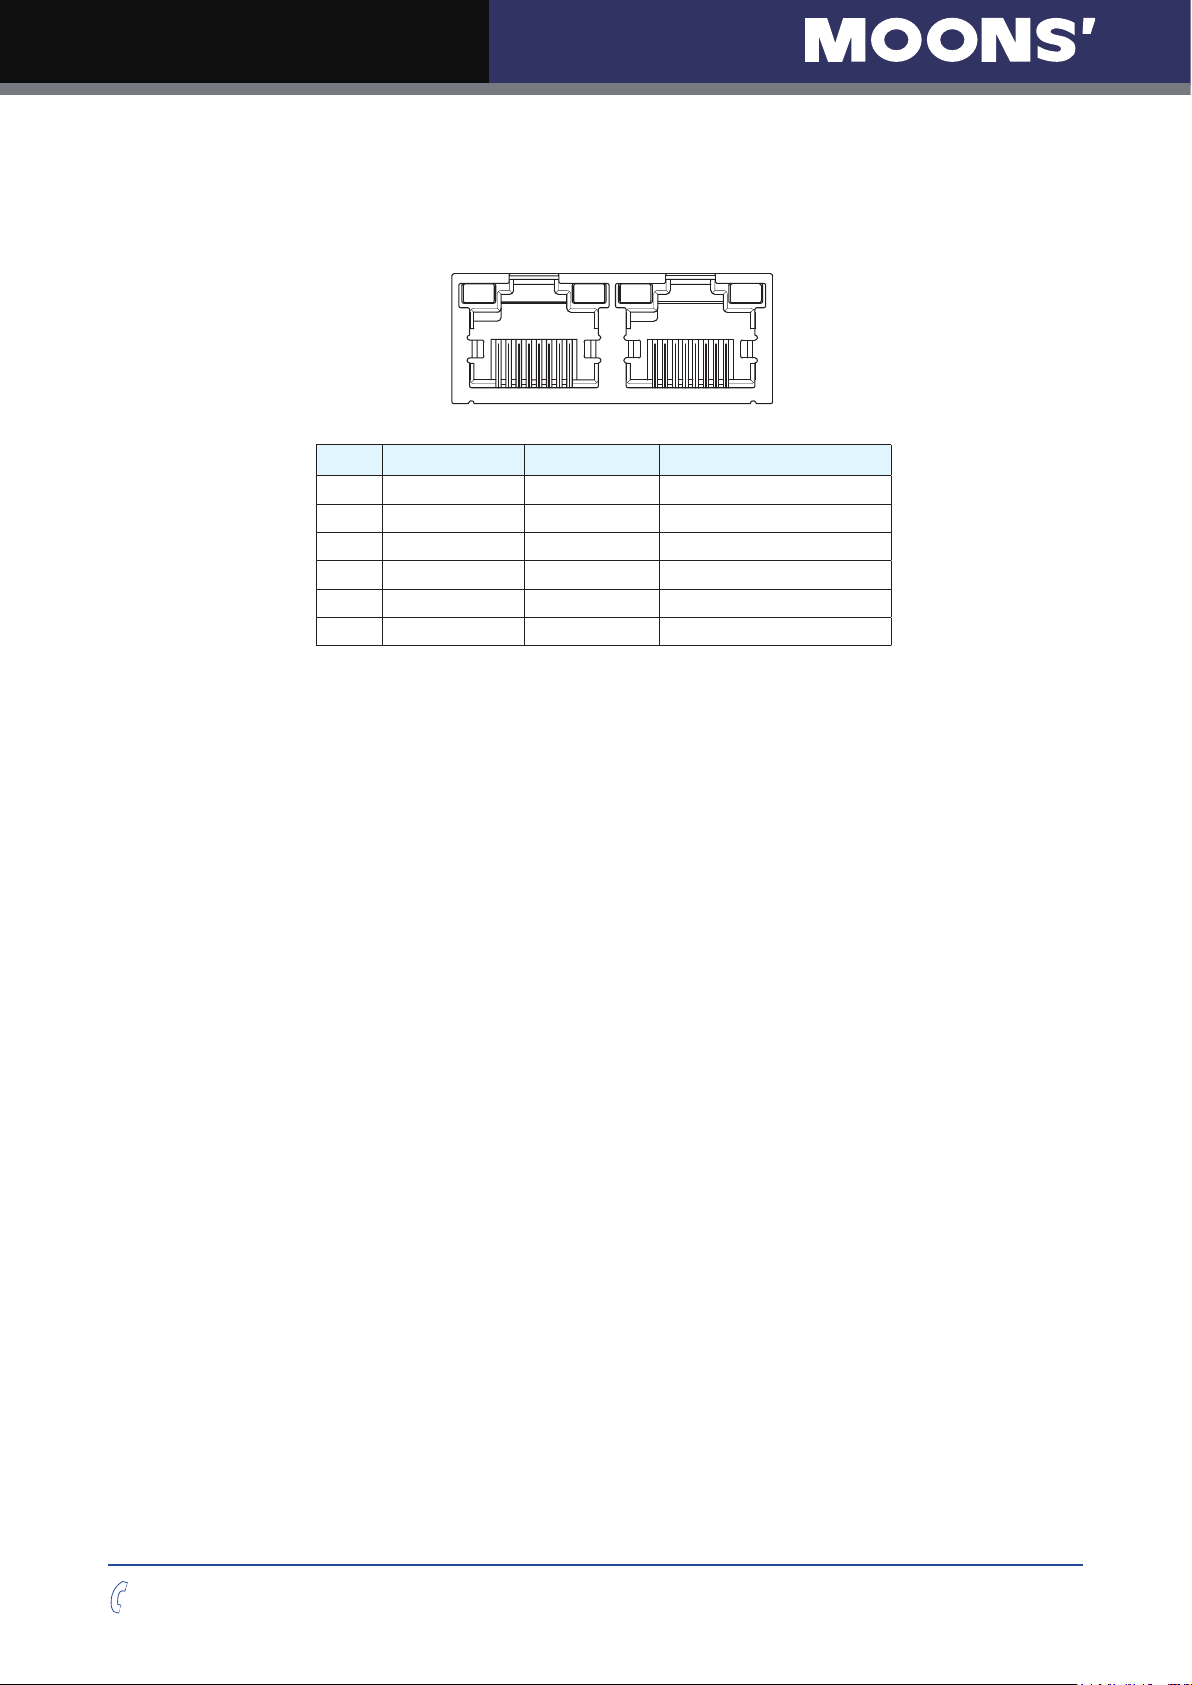
CANopen COM Port
COM1 COM2
PIN COM1 Signal COM2 Signal Wire Color
1 CAN_H CAN_H ORG/WHT
2 CAN_L CAN_L ORG
3,7,8 GND GND GRN/WHT, BRN/WHT, BRN
4 RS-232_TX NC BLU
5 RS-232_RX NC BLU/WHT
6 NC NC GRN
1818
PC connection with RS-232 cable
Before using STF congurator for –C drive configuration, please connect COM1 on the driver to
host PC by RS-232 programming cable.
CANopen network connection
Multiple –C model drive network can be built via dual CANopen communication port by network
cable provided.
NOTE: The CANopen port on the drive is isolated from internal circuitry of the drive. So the
GND of each drive’s CANopen port must be connected together. The rst drive’s GND of
the CANopen port must be connected to the GND of CANopen port on the controller.
400-820-9661
11
Rev. 1.0
11/08/2017
Page 12
STF-R/C Hardware Manual
2.4 Setting bus address and baud rate
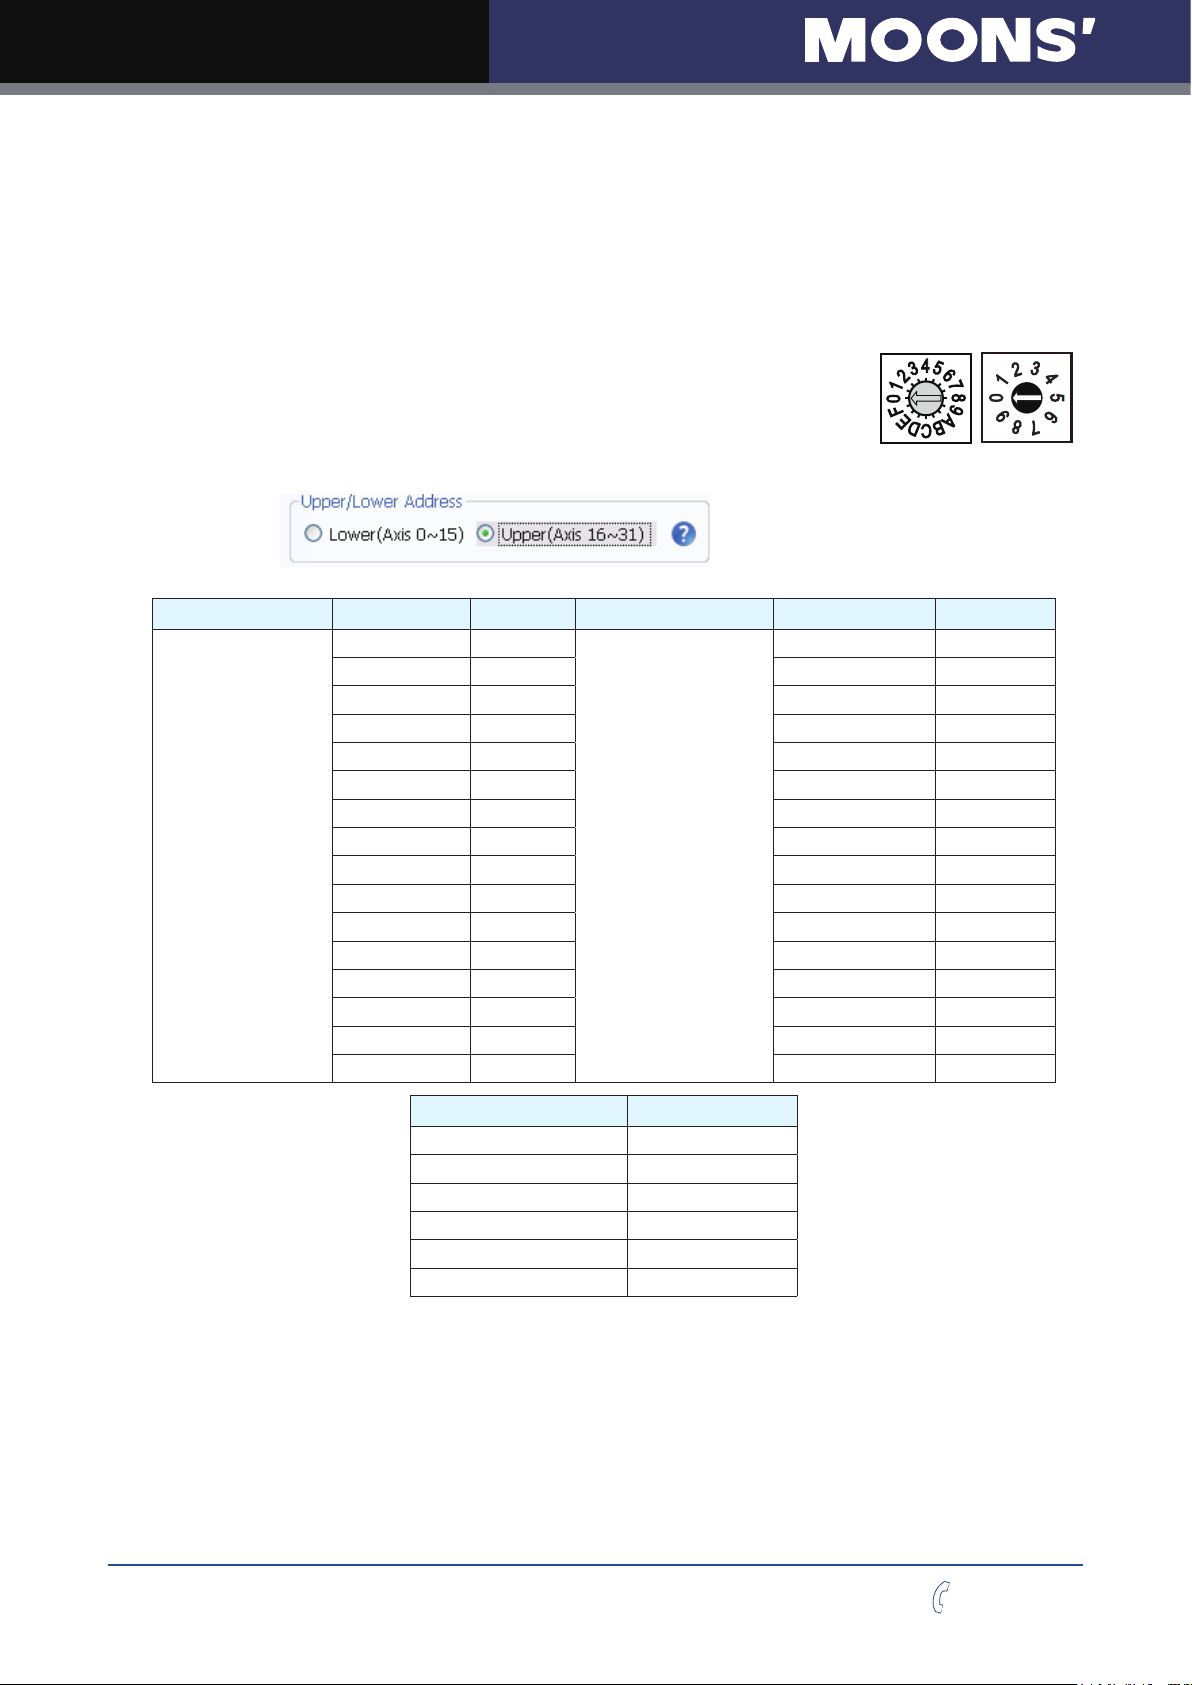
STF drives (-R model and -C model) have two rotary switches to set the bus address and baud
rate.
2.4.1 RS-485 address and baud rate settings(-R model)
Set drive’s RS-485 address by rotary switch S1
Set drive’s RS-485 baud rate by rotary switch S2
RS-485
Address
S1 is used to set drive’s RS-485 address, and the range is 0~F (0~15 in
decimal). If you want to set the drive’s RS-485 address range to 10~1F
(16~31 in decimal), you need to congure it in STF Congurator software.
Upper/Lower addr S1 position SCL addr Upper/Lower addr S1 position SCL addr
Lower(Axis 0~15)
0 0
1 1 1 !
2 2 2 "
3 3 3 #
4 4 4 $
5 5 5 %
6 6 6 &
7 7 7 '
8 8 8 (
9 9 9 )
A : A *
B ; B +
C < C ,
D = D E > E .
F ? F /
Upper(Axis 16~31)
0 @
S1
RS-485
Baud Rate
S2
Rev. 1.0
11/08/2017
S2 position Baud Rate (bps)
0 9600
1 19200
2 38400
3 57600
4 115200
5-9 Reserved
12
400-820-9661
Page 13
STF-R/C Hardware Manual
2.4.2 CANopen address and baud rate settings(-C model)
Set drive’s CANopen address by rotary switch S1
Set drive’s CANopen baud rate by rotary switch S2
CANopen
Address
CANopen
Baud Rate
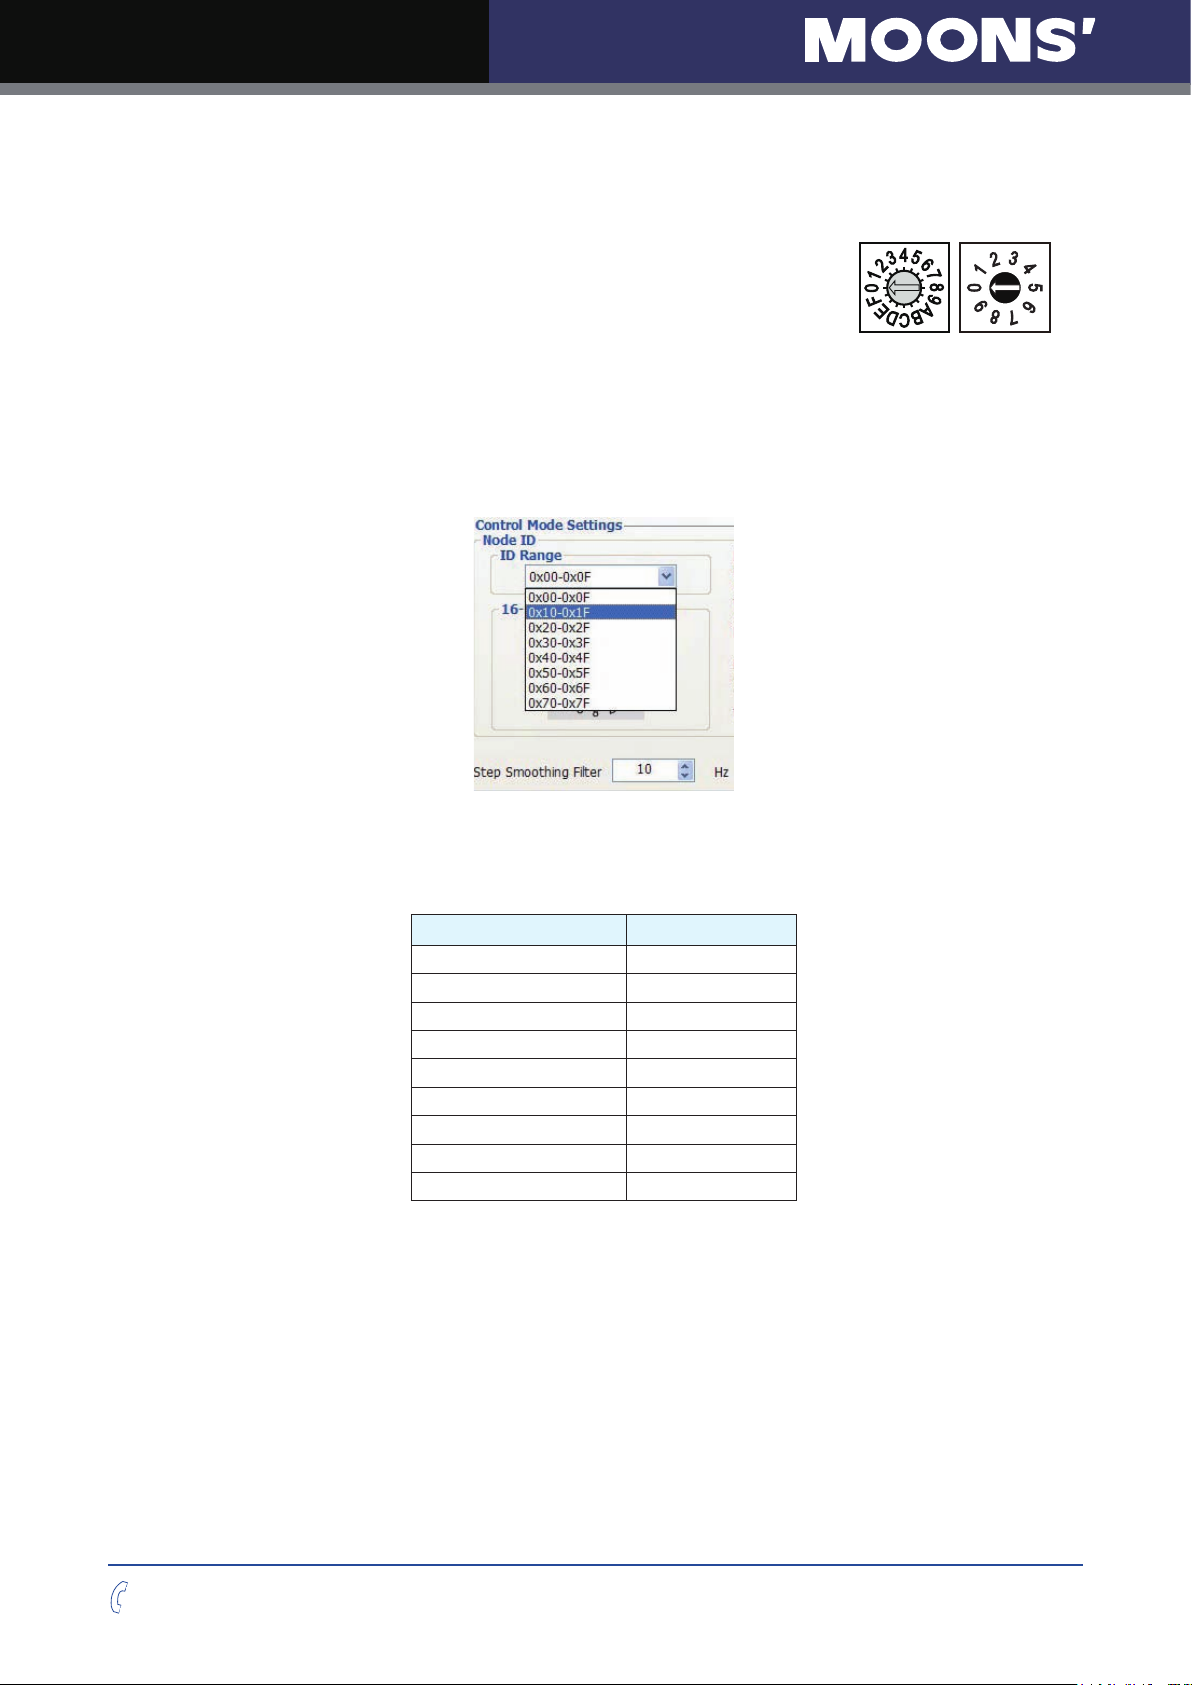
Each node on a CANopen network must have a unique Node ID. Valid
ranges for the Node ID are 0x01 through 0x7F (1~127). Node ID 0x00
S1
S2
is reserved in accordance with CiA301. The Node ID is selected using
rotary switches and software; one sixteen position switch set the lower four bits (0~F) of node ID,
while upper three bits of node ID are congured by STF Congurator software. Each time when
Node ID is changed, a power cycle is required before the new Node ID is valid.
Please refer to the CANopen manual for more information.
CANopen Baud Rate
There are 8 types of baud rate supported by CANopen communication on STF drive. It is set via
S2 switch on the drive
S2 position Baud Rate (bps)
0 1M
1 800K
2 500K
3 250K
4 125K
5 50K
6 20K
7 12.5K
8-9 Reserved
400-820-9661
13
Rev. 1.0
11/08/2017
Page 14
STF-R/C Hardware Manual
2.5 Connecting the Power Supply
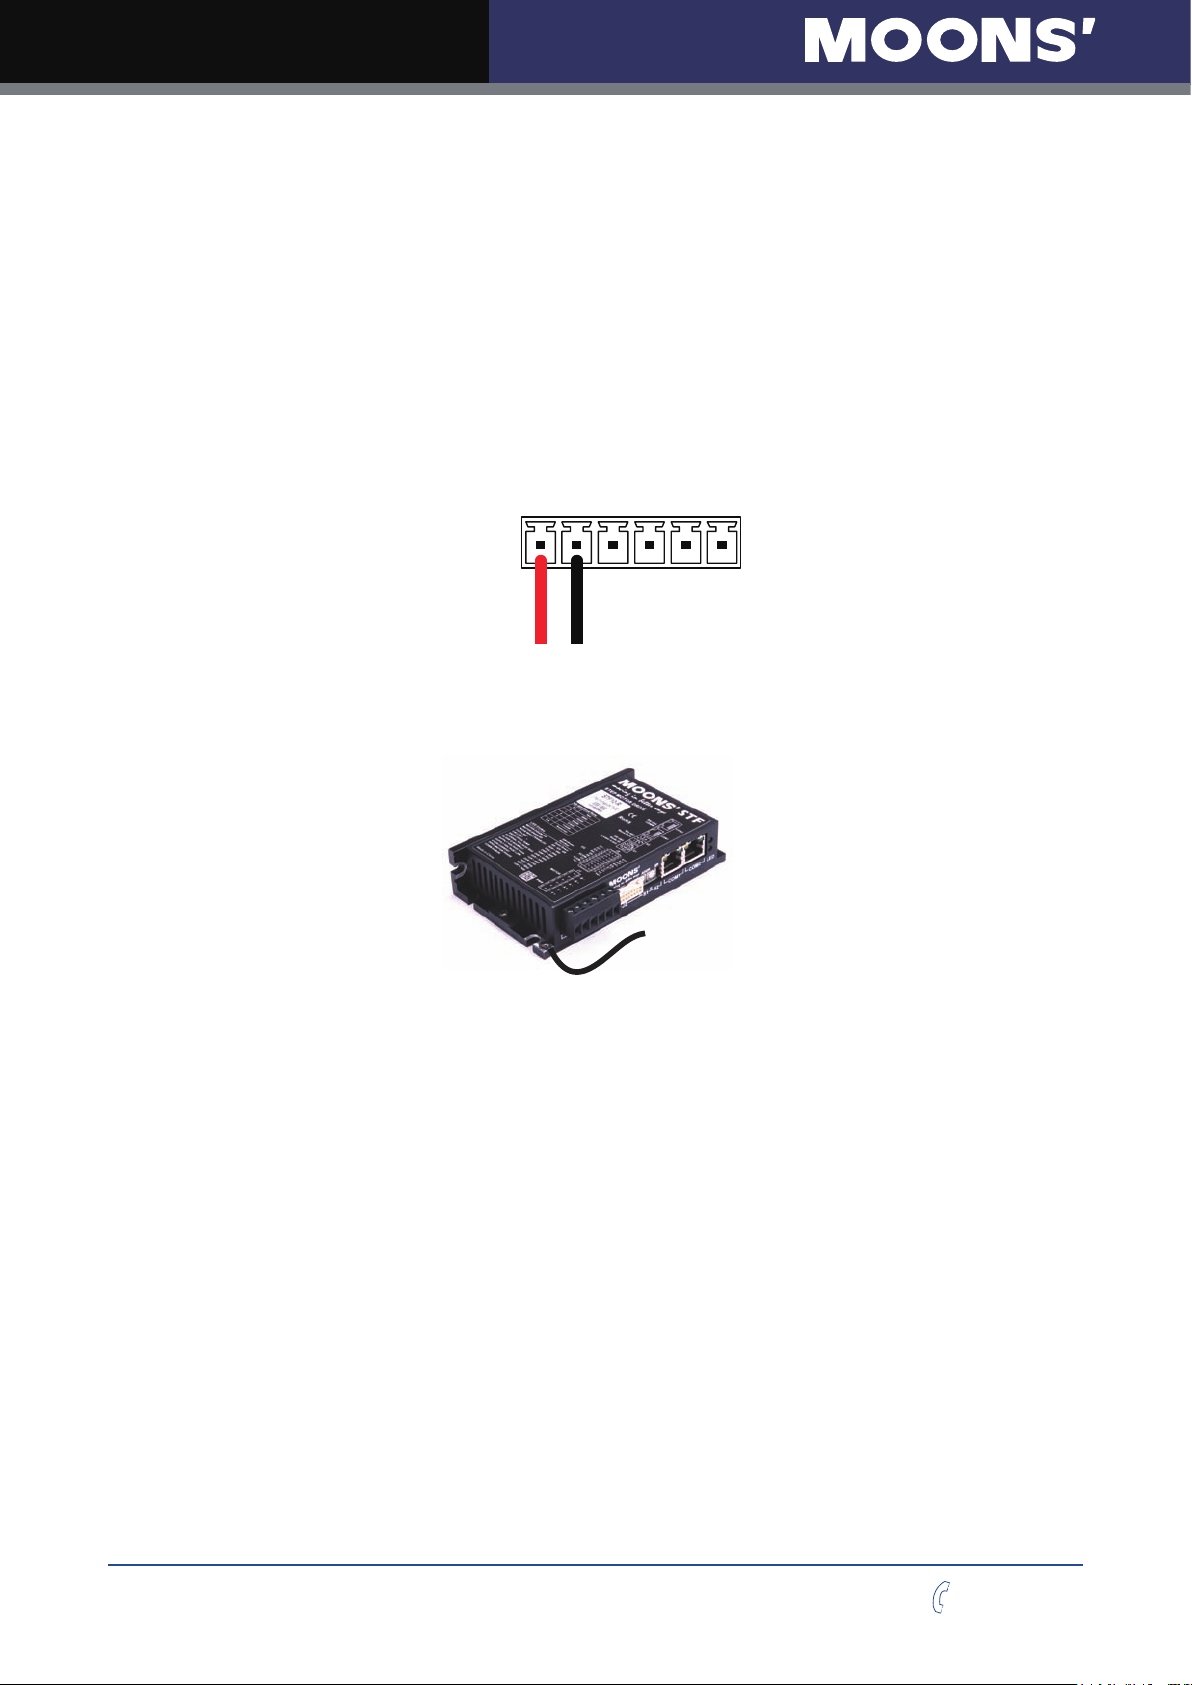
Connect power supply “+” terminal to the drive terminal labeled “V+”.
Connect power supply “-” terminal to the drive terminal labeled “V-”.
STF03 accepts DC voltage range from 12 – 48VDC
STF05 accepts DC voltage range from 24 – 48VDC
STF06 accepts DC voltage range from 12 – 48VDC
STF10 accepts DC voltage range from 24 – 70VDC
Warning: DO NOT reverse the wires
NOTE: DO NOT apply power until all connections to the drive have been made
V+J1V-
Power Connector
Ensure a proper earth ground connection by using the screw on the left side of the chassis.
To Earth Ground
Please read “choosing a power supply” for more details.
Rev. 1.0
11/08/2017
14
400-820-9661
Page 15
STF-R/C Hardware Manual
2.6 Choosing A Power Supply
The main considerations when choosing a power supply are the voltage and current requirements
of the application.
2.6.1 Voltage
The STF drive and motor is designed to give optimum performance between 24~48 Volts DC. Choosing
the voltage depends on the performance needed and diver/motor heating that acceptable and/or does
not cause a drive over-temperature. Higher voltage will give higher speed performance, but will cause
the drive to produce higher temperatures. Using power supplies with voltage outputs that are near the
drive maximum may signicantly reduce the operational duty cycle.
The STF03/06 drive extended range of operation voltage can be as low as 11VDC minimum to as
high as 53VDC maximum. When operation below 11VDC, the STF03/06 series will work unstable.
The supply input cannot go blow 11VDC for reliable operation, otherwise under voltage alarm will be
triggered. STF03/06 drive will stop working when this alarm is triggered.
The STF10 drive extended range of operation voltage can be as low as 18VDC minimum to as high as
75VDC maximum (18-53VDC for STF05 Drives). When operation below 18VDC, the STF05/10 series
will work unstable. The supply input cannot go blow 18VDC for reliable operation, otherwise under
voltage alarm will be triggered. STF05/10 drive will stop working when this alarm is triggered.
STF03/05/06
If a regulated power supply is used, and that is near the driver maximum voltage of 53VDC ,a voltage
clamp may be required to prevent the voltage over 53VDC which will occurs a overvoltage fault. When
using an unregulated power supply, make sure the no-load voltage of the supply does not exceed the
maximum input voltage 53VDC.
STF10
If a regulated power supply is used, and that is near the driver maximum voltage of 75VDC ,a voltage
clamp may be required to prevent the voltage over 75VDC which will occurs a overvoltage fault. When
using an unregulated power supply, make sure the no-load voltage of the supply does not exceed the
maximum input voltage 75VDC.
2.6.2 Current
When STF drives work with different motors, the recommended power supply output current
capacity under different supply voltage is shown in below table. The STF drive power supply
current is
high voltage and low current into low voltage and high current.
exceeds the motor voltage,the less current will be required from the power supply.
It is important to note that the current draw is significantly different at higher speeds depending
on the torque load to the motor. Estimat
analysis of the load to the motor
lower than the the winding currents because it uses switching amplifiers to convert a
The more power supply voltage
ing how much current is necessary may require a good
.
Drive Motor Voltage Current Drive Motor Voltage Current
STF03
STF05
STF06
400-820-9661
AM8 24V above 1A
AM11 24V above 1A 48V above 4A
AM14 24V above 1A 70V above 4A
AM17
AM23
AM24
24V above 1.5A
48V above 1.5A 48V above 4.5A
24V above 3A 70V above 4.5A
48V above 4A
24V above 4.5A 48V above 6A
48V above 4.5A 70V above 6A
STF10
AM23
AM24
AM34
15
24V above 3A
24V above 4.5A
24V above 6A
Rev. 1.0
11/08/2017
Page 16
STF-R/C Hardware Manual
2.7 Connecting the motor
For MOONS’stepper motor, please connect black, green, red, blue wires to drive’s A+, A-, B+
and B- correspondingly.
A+J1A- B+ B-
Motor Connector
If using a non-MOONS’motor, please refer to your motor specs for wiring information.
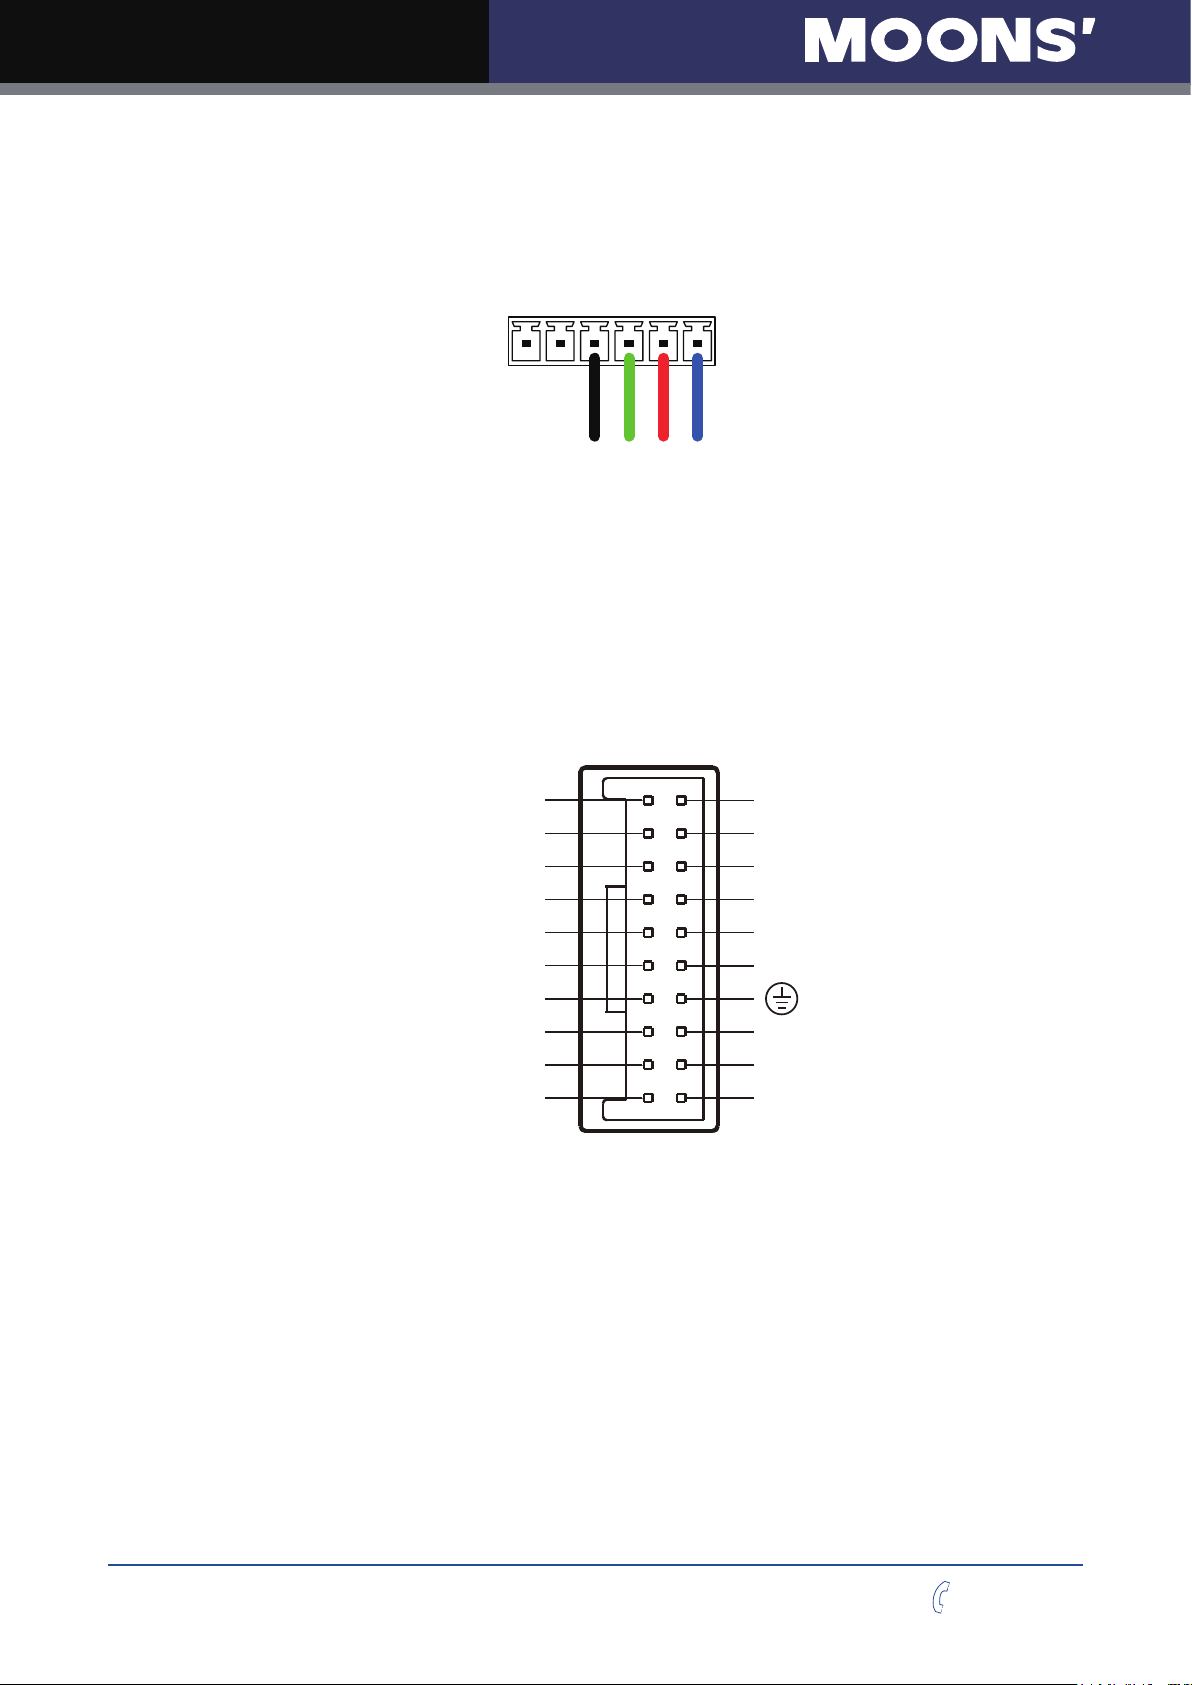
3 Inputs and Outputs
STF series drive inputs and outputs include:
• 8 optically isolated digital inputs, 5-24VDC for high level voltage
• 4 optically isolated digital outputs, maximum voltage 30V, maximum sinking or sourcing current
100mA
J2
X1X2X3X4-
X6
X8
XCOM
Y2
YCOM
2
4
6
8
10
12
14
16
18
20
Y4-
I/O Connector Diagram
1
3
5
7
9
11
13
15
17
19
X1+
X2+
X3+
X4+
X5
X7
Y1
Y3
Y4+
Rev. 1.0
11/08/2017
16
400-820-9661
Page 17
STF-R/C Hardware Manual
3.1 Digital Inputs
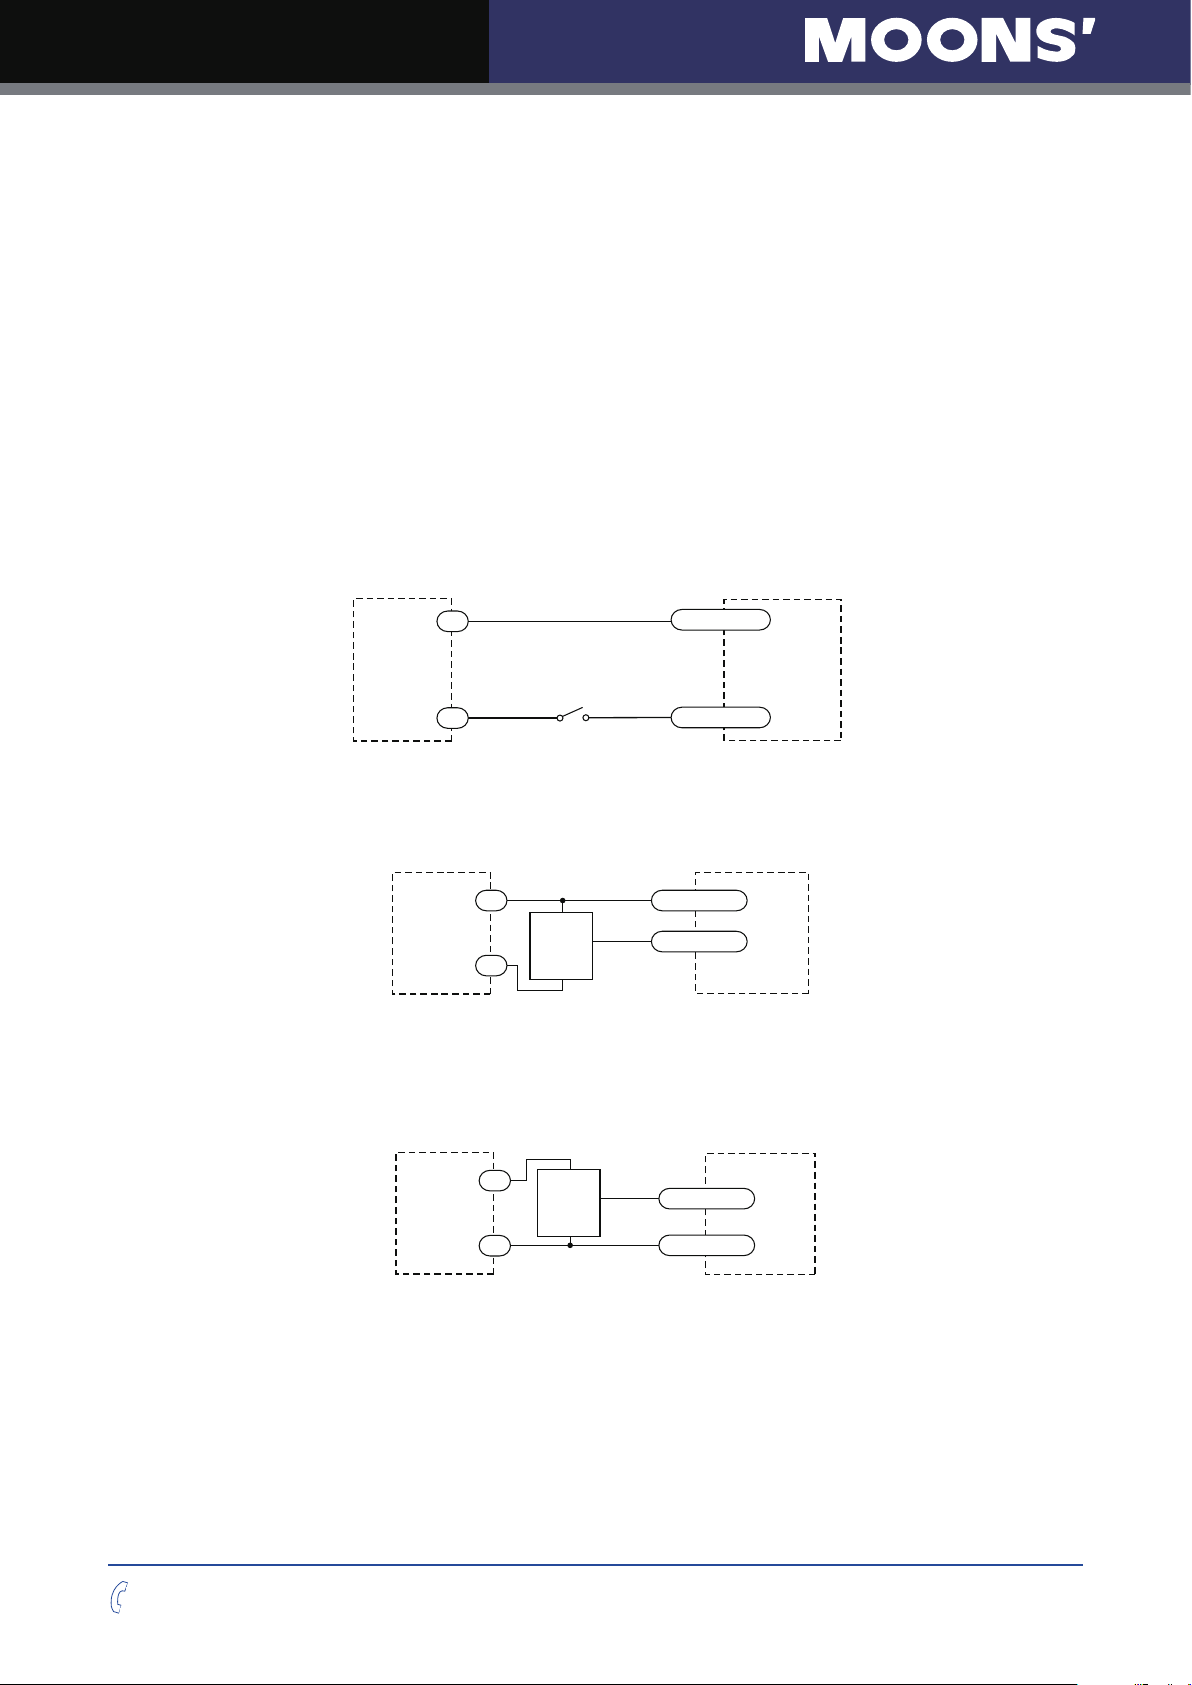
3.1.1 X1, X2, X3, X4 digital input signal
X1, X2: optically isolated, differential, 5-24VDC, minimum pulse width 250ns, maximum pulse
frequency 2MHz
X3, X4: optically isolated, differential, 5-24VDC, minimum pulse width 100μs, maximum pulse
frequency 5KHz
X1 can be used as general purpose input.
X2 can be used as general purpose input.
X3 can be used as CW limit input or general purpose input.
X4 can be used as CCW limit input or general purpose input.
Please use STF Congurator software for X1,X2,X
3 and X4 function configuration.
Following graphs shows some common connection methods for the inputs:
5-24
VDC
Power
Supply
+
Switch or Relay
(closed = logic Low)
-
X1/2/3/4+
STF
Drive
X1/2/3/4-
Connecting the inputs to a Switch or Relay
5-24
VDC
Power
Supply
+
+
NPN
Output
-
output
–
X1/2/3/4+
X1/2/3/4-
STF
Drive
Connecting the inputs to a NPN type output
400-820-9661
5-24
VDC
Power
Supply
+
-
+
PNP
Output
–
output
X1/2/3/4+
X1/2/3/4-
STF
Drive
Connecting the inputs to a PNP type output
17
Rev. 1.0
11/08/2017
Page 18
STF-R/C Hardware Manual
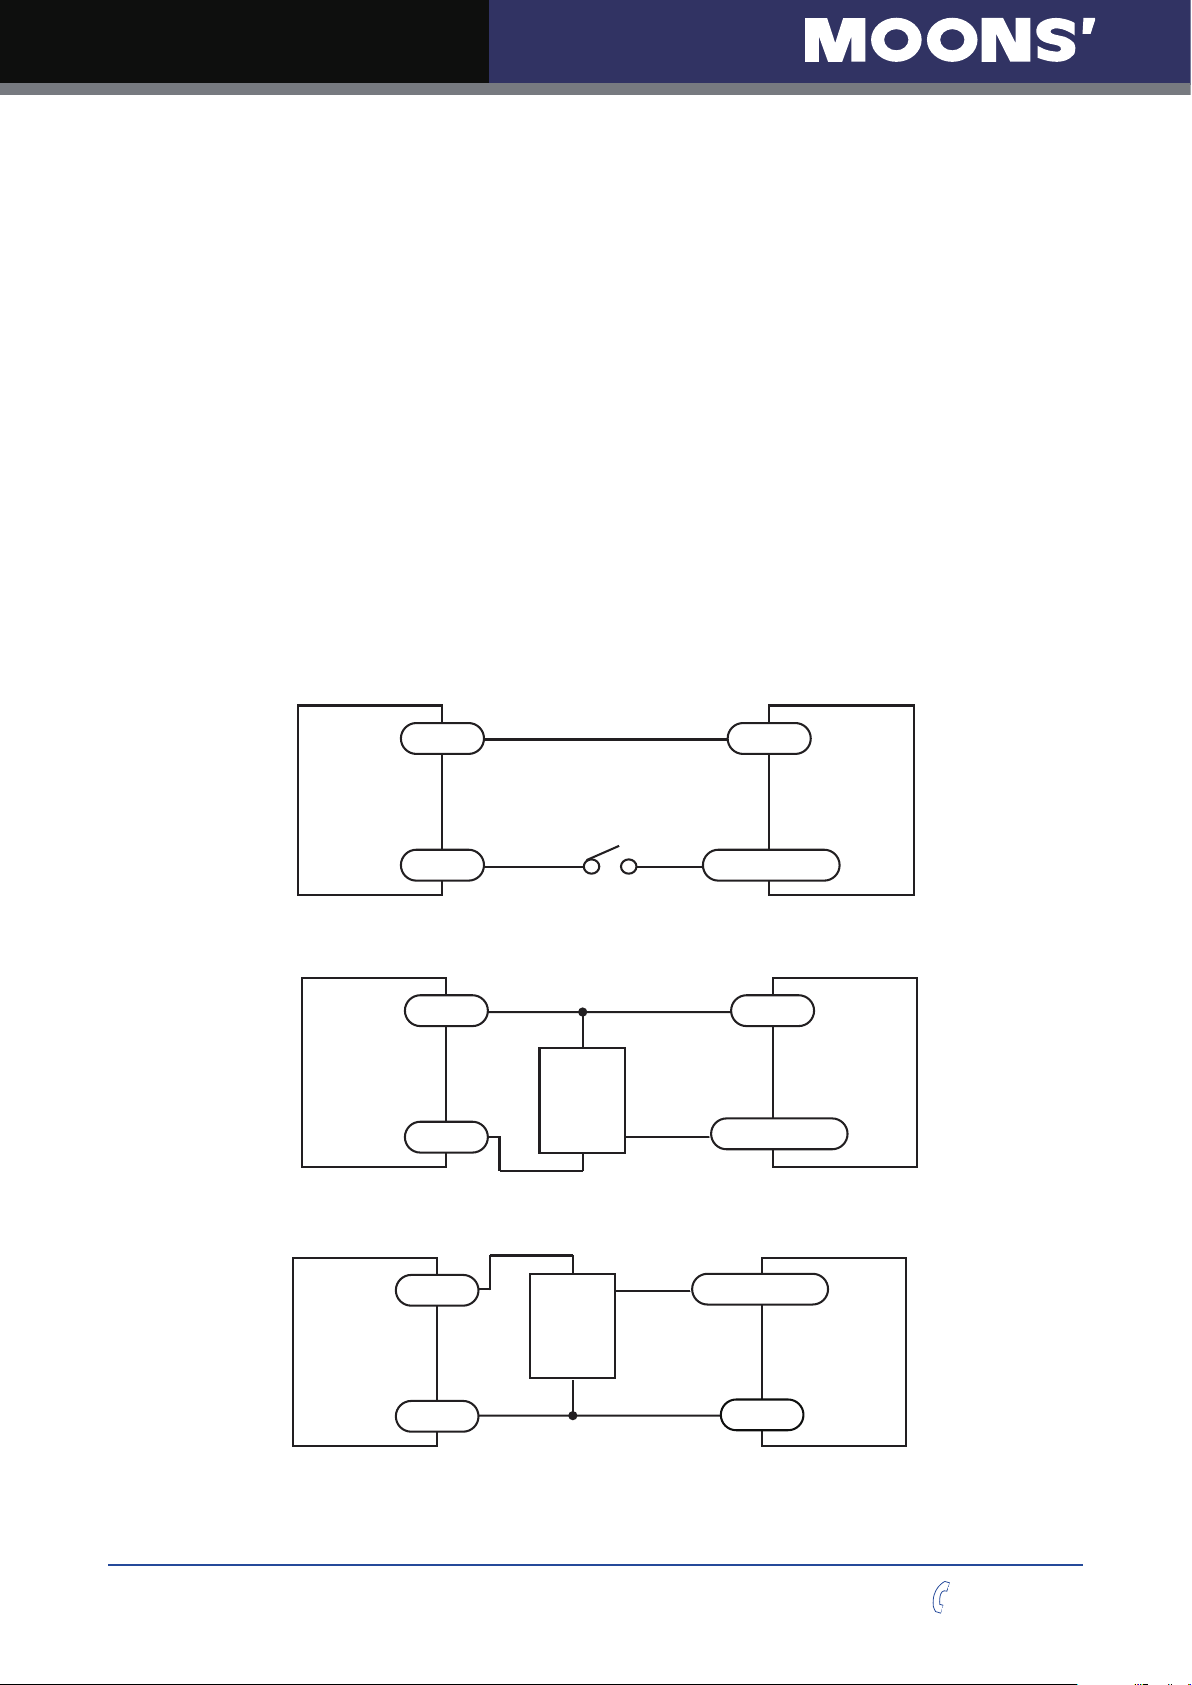
3.1.2 X5, X6, X7, X8 digital input signal
X5,X6,X7,X8: optically isolated, single-ended, 5-24VDC, minimum pulse width 100μs, maximum pulse
frequency 5KHz
X5 can be used as enable input or general purpose input.
X6 can be used as alarm reset input or general purpose input.
X7 can be used as general purpose input.
X8 can be used as general purpose input.
Because the input is an optically isolated circuit, a 5-24V power supply is needed. For example,
you can use the power supply of the PLC when you are using a PLC control system, but if you
want to connect a relay or mechanical switch to the input , you must need a power supply.
XCOM is an electronics term for a single-ended signal connection to a common voltage. In the
case of STF series, if you are using a sourcing (PNP) input signals, you need to connect XCOM
to the ground (power supply -), if you are using a sinking(NPN) input signals ,the XCOM need to
connect to the power supply +.
Please use STF Congurator software for X5,X6,X7 and X8 function conguration. Following
graphs shows some common connection methods for the inputs:
XCOM
STF
Drive
X5/X6/X7/X8
5-24VDC
Power
Supply
+
Switch or Relay
(closed = logic Low)
-
Connecting the inputs to a Switch or Relay
XCOM+
5-24VDC
Power
Supply
+
NPN
Output
-
output
-
X5/X6/X7/X8
STF
Drive
Connecting the inputs to a NPN type output
Rev. 1.0
11/08/2017
output
5-24VDC
Power
Supply
+
+
PNP
Output
-
X5/X6/X7/X8
-
Connecting the inputs to a PNP type output
18
STF
Drive
XCOM
400-820-9661
Page 19
STF-R/C Hardware Manual
Connecting a sinking output
Connecting a sinking output with PLC’s input
Connecting a sourcing output with PLC’s input
STF
Drive
5-24 VDC
Power Supply
+ –
Load
Y1/2/3-
Y1/2/3+
CLP
CDV 42-5
ylppuS rewoP
+ –
Y1/2/3-
Y1/2/3+
IN
COM
STF
Drive
PLC
5-24 VDC
Power Supply
+
–
Y1/2/3-
Y1/2/3+
COM
IN
STF
Drive
3.2 Digital Outputs
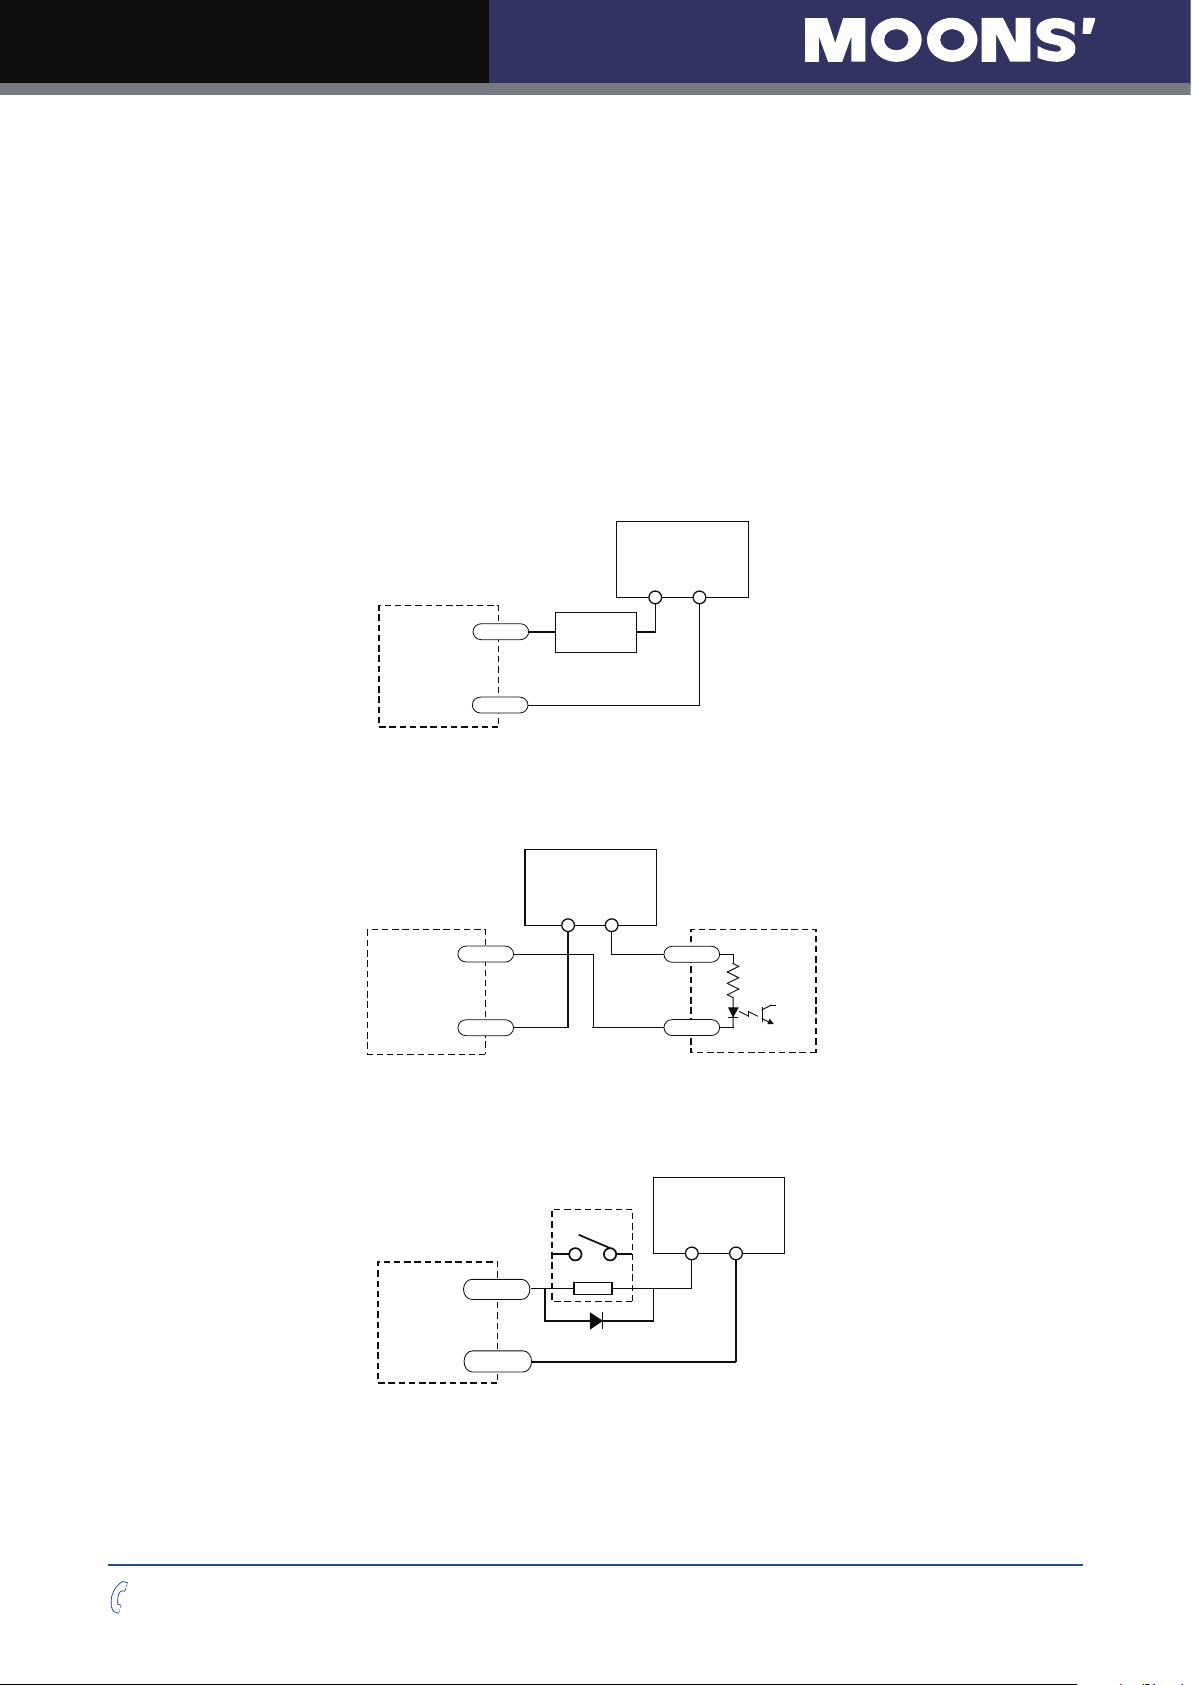
3.2.1 Y1, Y2, Y3 Digital Outputs
Y1 can be used as alarm output, motion status output or general purpose output.
Y2 can be used as brake output, motion status output or general purpose output.
Y3 cab be used as tach-out, timing signal output(50pulse/rev), motion status output or general
purpose output.
Please use STF Congurator software for Y1,Y2 and Y3 function conguration.
Following graphs shows some common connection methods for the outputs:
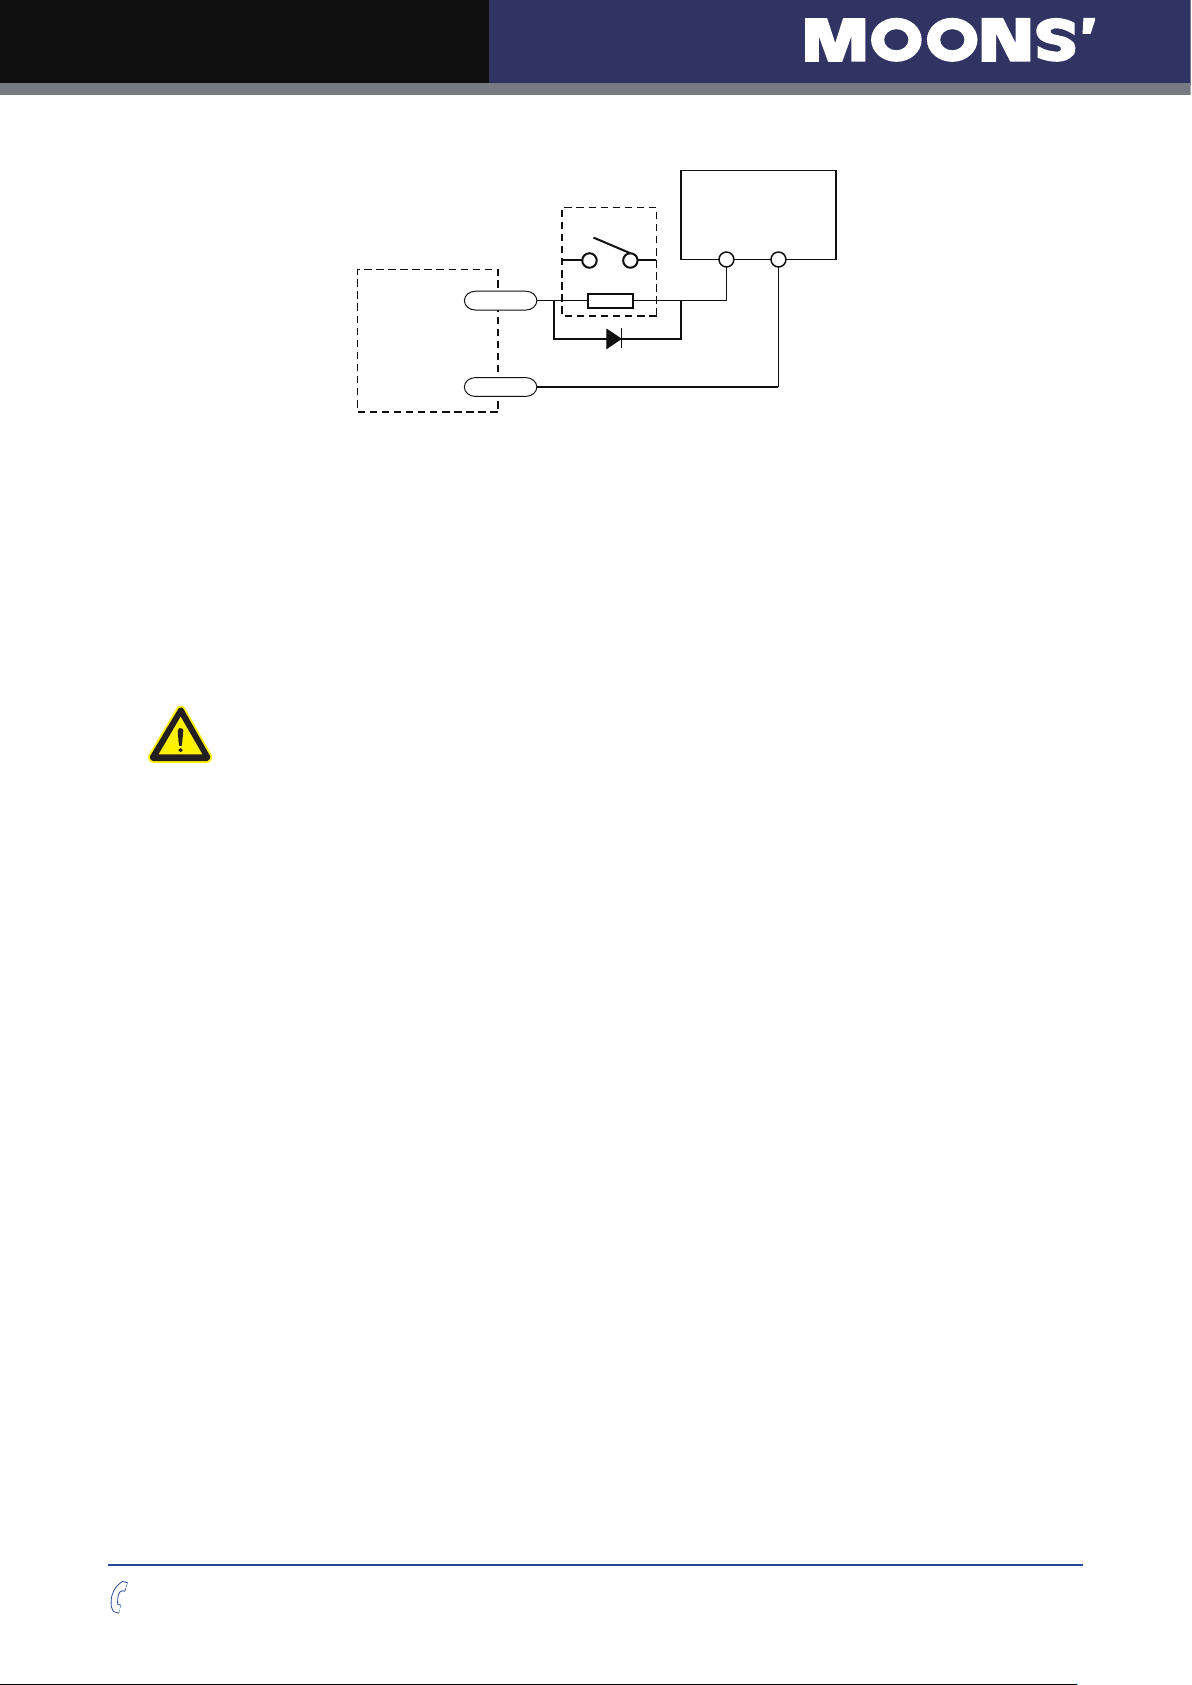
NOTE: Do not connect the outputs to more than 30VDC power supply. And the current of
each output terminal must not exceed 100mA.
STF
Drive
Y1/2/3+
Y1/2/3-
5-24 VDC
Power Supply
+ –
Load
Connecting a sinking output
STF
Drive
Connecting a sinking output with PLC’s input
STF
Drive
5-24 VDC
Power Supply
+
–
Y1/2/3+
COM
PLC
Y1/2/3-
relay
Y1/2/3+
1N4935 suppression diode
Y1/2/3-
IN
5-24 VDC
Power Supply
+ –
400-820-9661
Driving a relay
19
Rev. 1.0
11/08/2017
Page 20
STF-R/C Hardware Manual
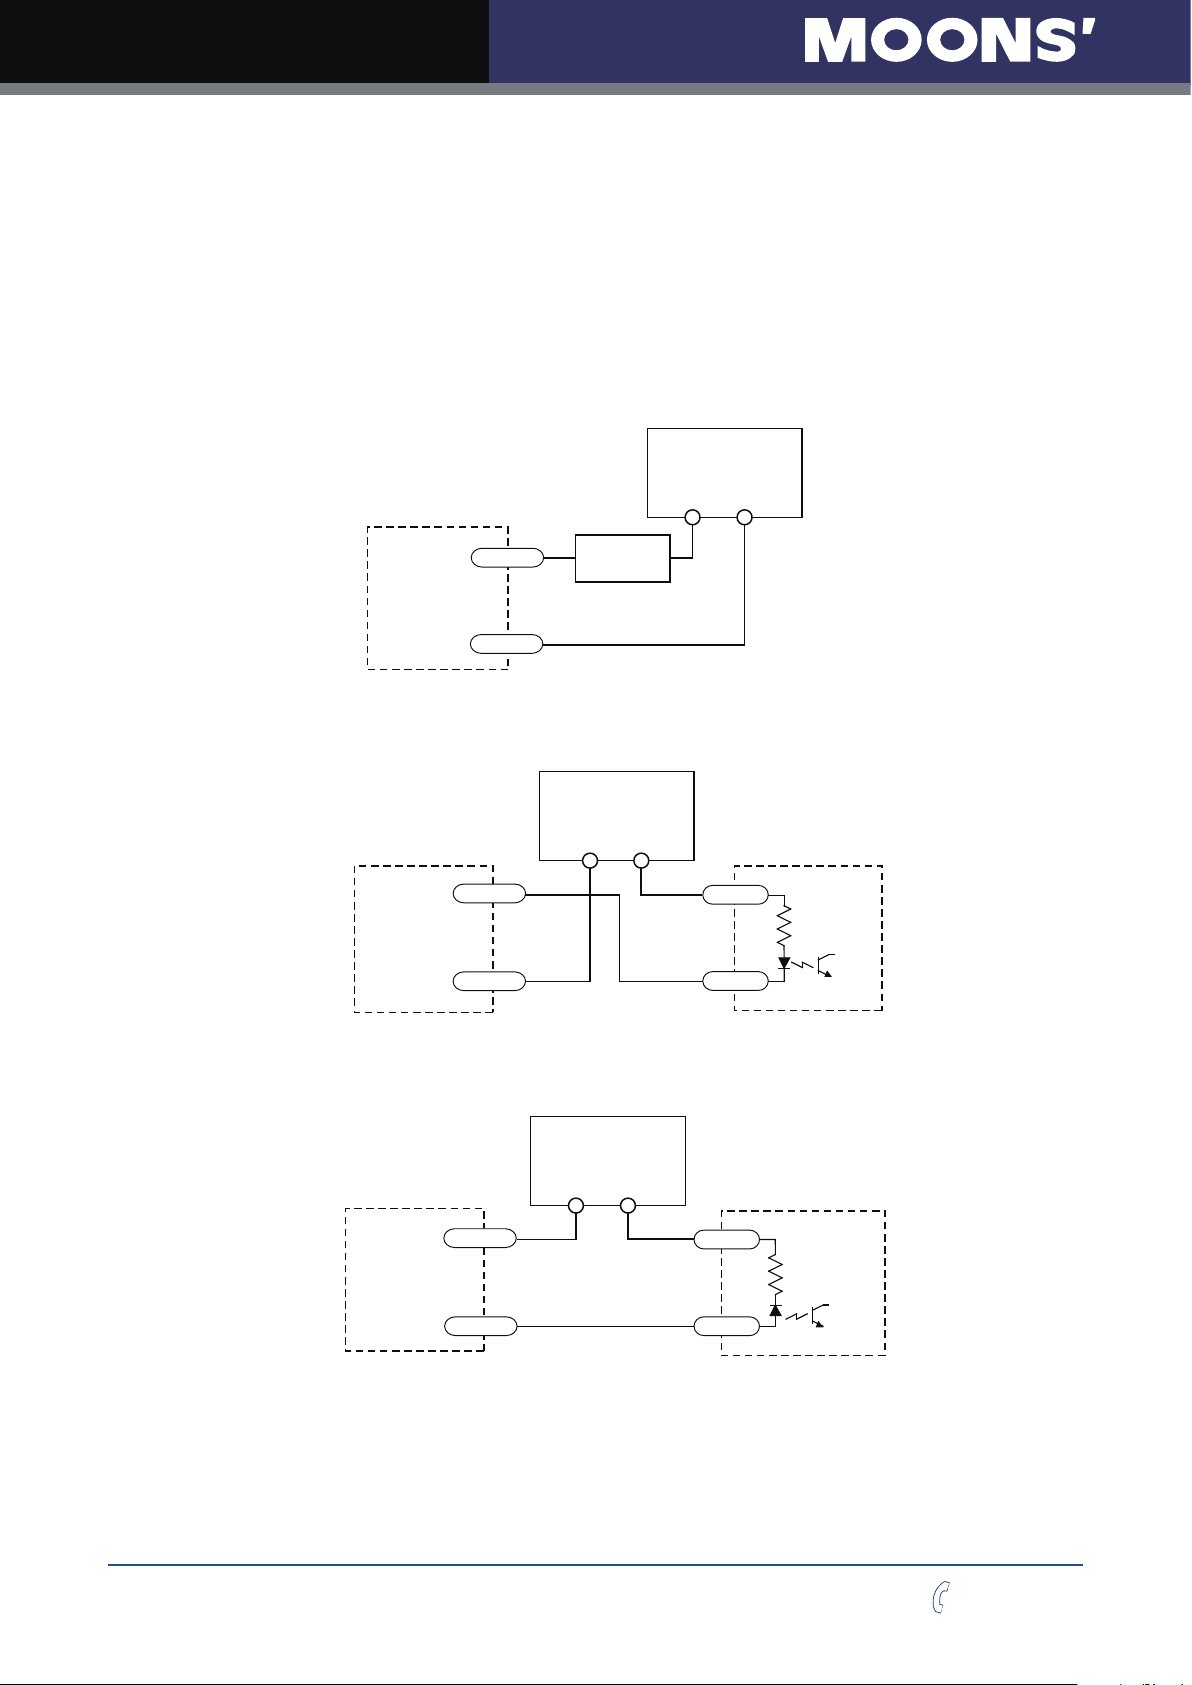
3.2.2 Y4 Digital Output
Y4 can be used as motion state output or general purpose output.
Please use STF Congurator software for Y4 function configuration.
Following graphs shows some common connection methods for the outputs:
NOTE: Do not connect the outputs to more than 30VDC power supply. And the current of
each output terminal must not exceed 100mA.
5-24 VDC
Power Supply
+ –
Y4+
Load
STF
Drive
Y4-
Connecting a sinking output
5-24 VDC
Power Supply
+
–
Y4+
STF
COM
PLC
Drive
Y4-
IN
Connecting a sinking output with PLC’s input
Rev. 1.0
11/08/2017
5-24 VDC
Power Supply
+ –
Y4+
COM
STF
Drive
Y4-
IN
Connecting a sourcing output with PLC’s input
20
CLP
400-820-9661
Page 21
STF-R/C Hardware Manual
+ –
Y4-
Y4-
Y4-
Y4+
Y4+
Y4+
CLP
+ –
IN
COM
PLC
+
–
COM
IN
STF
Drive
STF
Drive
STF
Drive
Connecting a sinking output
Connecting a sinking output with PLC’s input
Connecting a sourcing output with PLC’s input
Load
5-24 VDC
Power Supply
5-24 VDC
Power Supply
5-24 VDC
Power Supply
4 Mounting the Drive
Use the M3 or M4 screw to mount the STF series drive .The drive should be securely fastened
to a smooth ,at metal surface the will help conduct heat away from the chassis. If this is not
possible, forced airow from a fan maybe required to prevent the drive from overheating.
STF
Drive
relay
Y4+
1N4935 suppression diode
Y4-
Driving a relay
5-24 VDC
Power Supply
+ –
• Never use the drive in a place where there is no air flow or the surrounding air is
more than 40℃.
• Never put the drive where it can get wet or where metal or other electrically
conductive particle particles can get on the circuity.
• Always provide air flow around the drive. When mounting multiple STF drives near
each other, maintain at least 2cm of space between drives.
400-820-9661
21
Rev. 1.0
11/08/2017
Page 22
STF-R/C Hardware Manual
5 Reference Materials
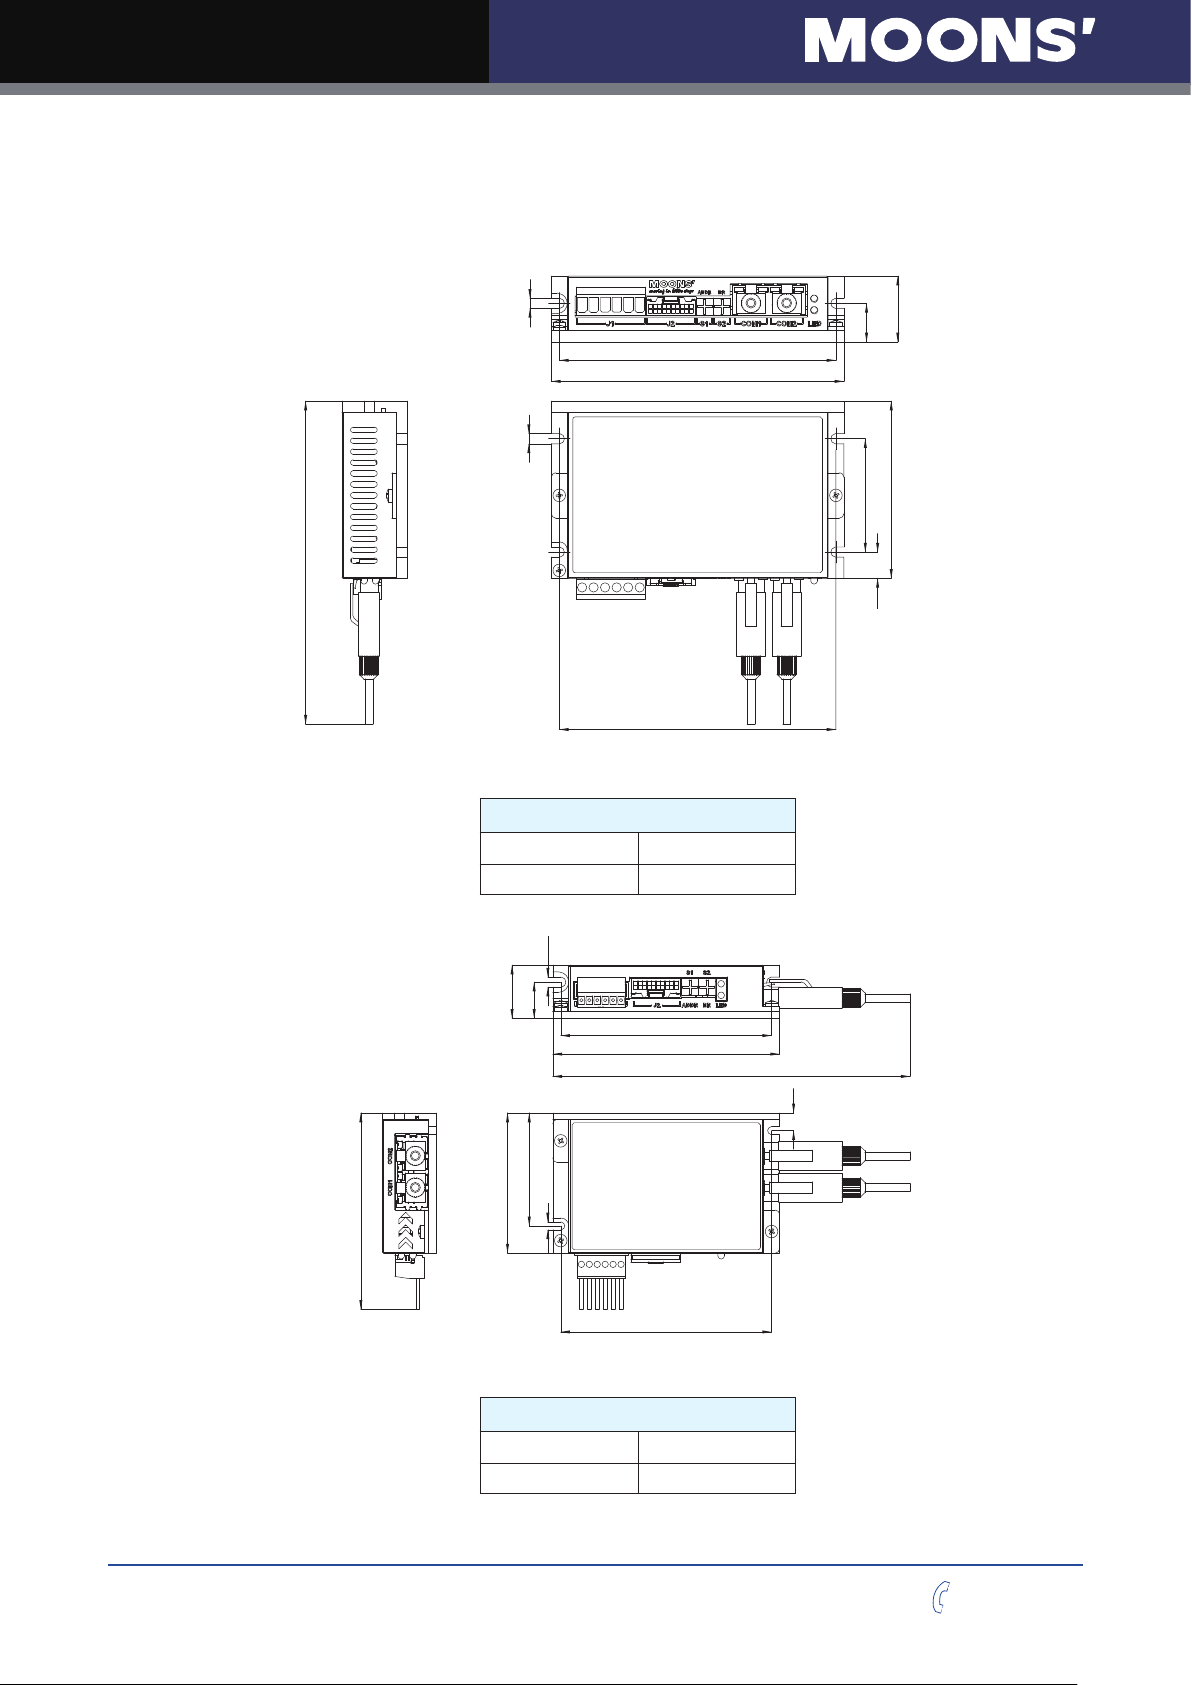
5.1 Drive Mechanical Outlines
142.5
4.54.5
122
129
122
Unit: mm
Model
STF05-R STF05-C
STF10-R STF10-C
50
17
29
78.2
11.6
86.6
4.5
23.5
16
93
100
49.8
61.8
3.5
93
Unit: mm
Model
STF03-R STF03-C
STF06-R STF06-C
157.6
7.8
Rev. 1.0
11/08/2017
22
400-820-9661
Page 23
STF-R/C Hardware Manual
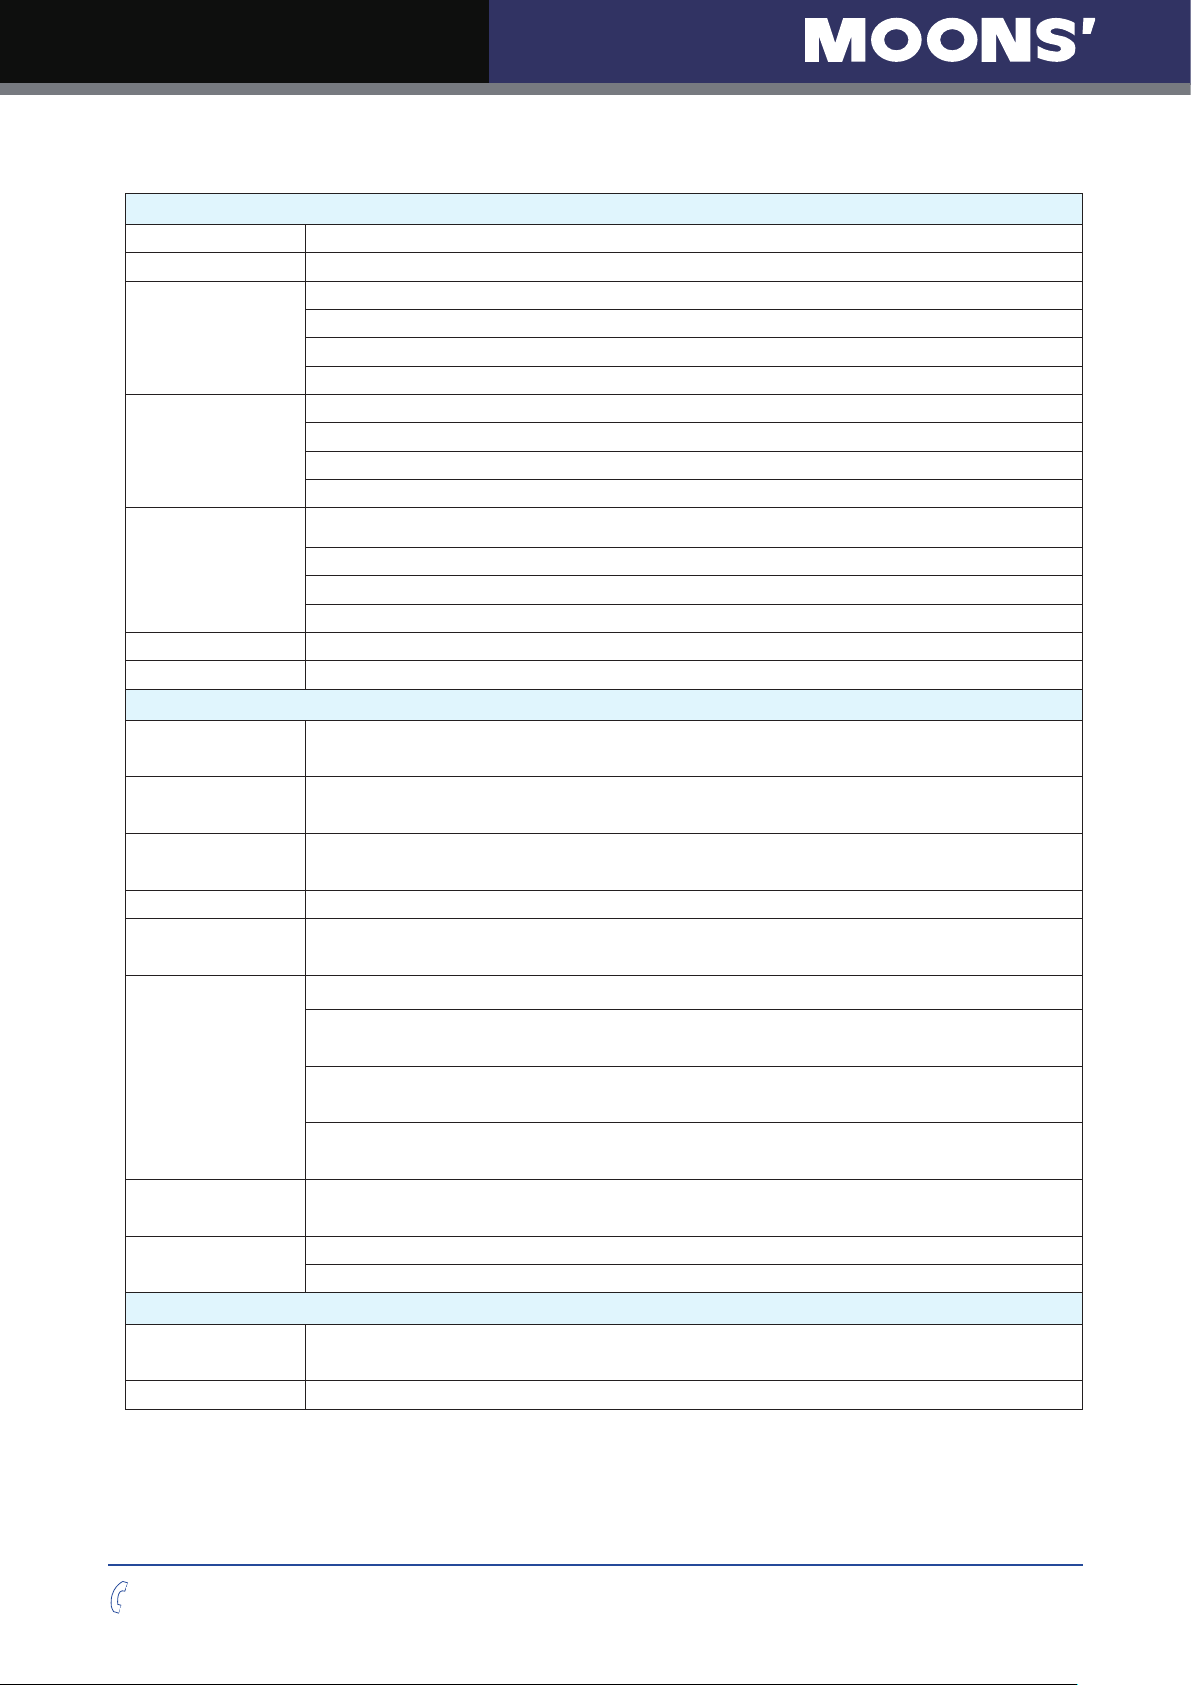
5.2 Technical Specifications
Power Amplifier
Amplier Type Dual H-Bridge, 4 Quadrant
Current Control 4 state PWM at 20KHz
STF03: 0.1 - 3.0A/phase(Peak-of-Sine) in 0.01Amp increment
Output Current
Rated input voltage
Absolute maximum
input voltage range
Protection Over voltage, under voltage, over temp, over current, open winding, communication cable disconnection
Idle Current Reduction Reduction range of 0 - 90% of running current after a delay selectable in milliseconds
Anti-Resonance
Torque Ripple
Smoothing
Auto Test & Auto
Setup
olatile Storage Configurations are saved in FLASH memory on-board the DSP
Non-V
Operation Mode
Digital Input
Digital Output
Communication
Interface
Ambient
Temperature
Humidity 90% non-condensing
STF05: 0.1 - 5.0A/phase(Peak-of-Sine) in 0.01Amp increment
STF06: 0.1 - 6.0A/phase(Peak-of-Sine) in 0.01Amp increment
STF10: 0.1 - 10.0A/phase(Peak-of-Sine) in 0.01Amp increment
STF03: 12 - 48VDC
STF05: 24 - 48VDC
STF06: 12 - 48VDC
STF10: 24 - 70VDC
STF03: 11 - 53VDC
STF05: 18 - 53VDC
STF06: 11 - 53VDC
STF10: 18 - 75VDC
Controller
Raises the system-damping ratio to eliminate midrange instability and allow stable operation
throughout the speed range of the motor
Allows for fine adjustment of phase current waveform harmonic content to reduce low-speed
torque ripple in the range of 0.25 to 1.5 rps
Auto test and setup at power on
performance.
R: SCL, Q, Modbus
C: Compliant with CiA301 and CiA402 standard
8 digital inputs
X1, X2: Optically isolated, differential, 5-24VDC for high level voltage,
minimum pulse width = 250ns, maximum pulse frequency = 2MHz
X3, X4: Opti
minimum pulse width = 100
X5 ~ X8: Optically isolated, single-ended, 5-24VDC for high level voltage,
minimum pulse width = 100μs, maximum pulse frequency = 5KHz
4 digital outputs
Y1 ~ Y4: Optically isolated, maximum voltage 30V, maximum sinking or sourcing current 100mA
R
model: dual port RS-485 (RJ45 connector)
cally isolated, differential, 5-24VDC for high level voltage,
(ie. motor resistance, and capacitance) to optimize your system
μs, maximum pulse frequency = 5KHz
C model: dual port CANopen (RJ45 connector) RS-232 included
Physical
0-40°C (32-104°F)(when mounted to a suitable heat sink)
400-820-9661
23
Rev. 1.0
11/08/2017
Page 24
STF-R/C Hardware Manual
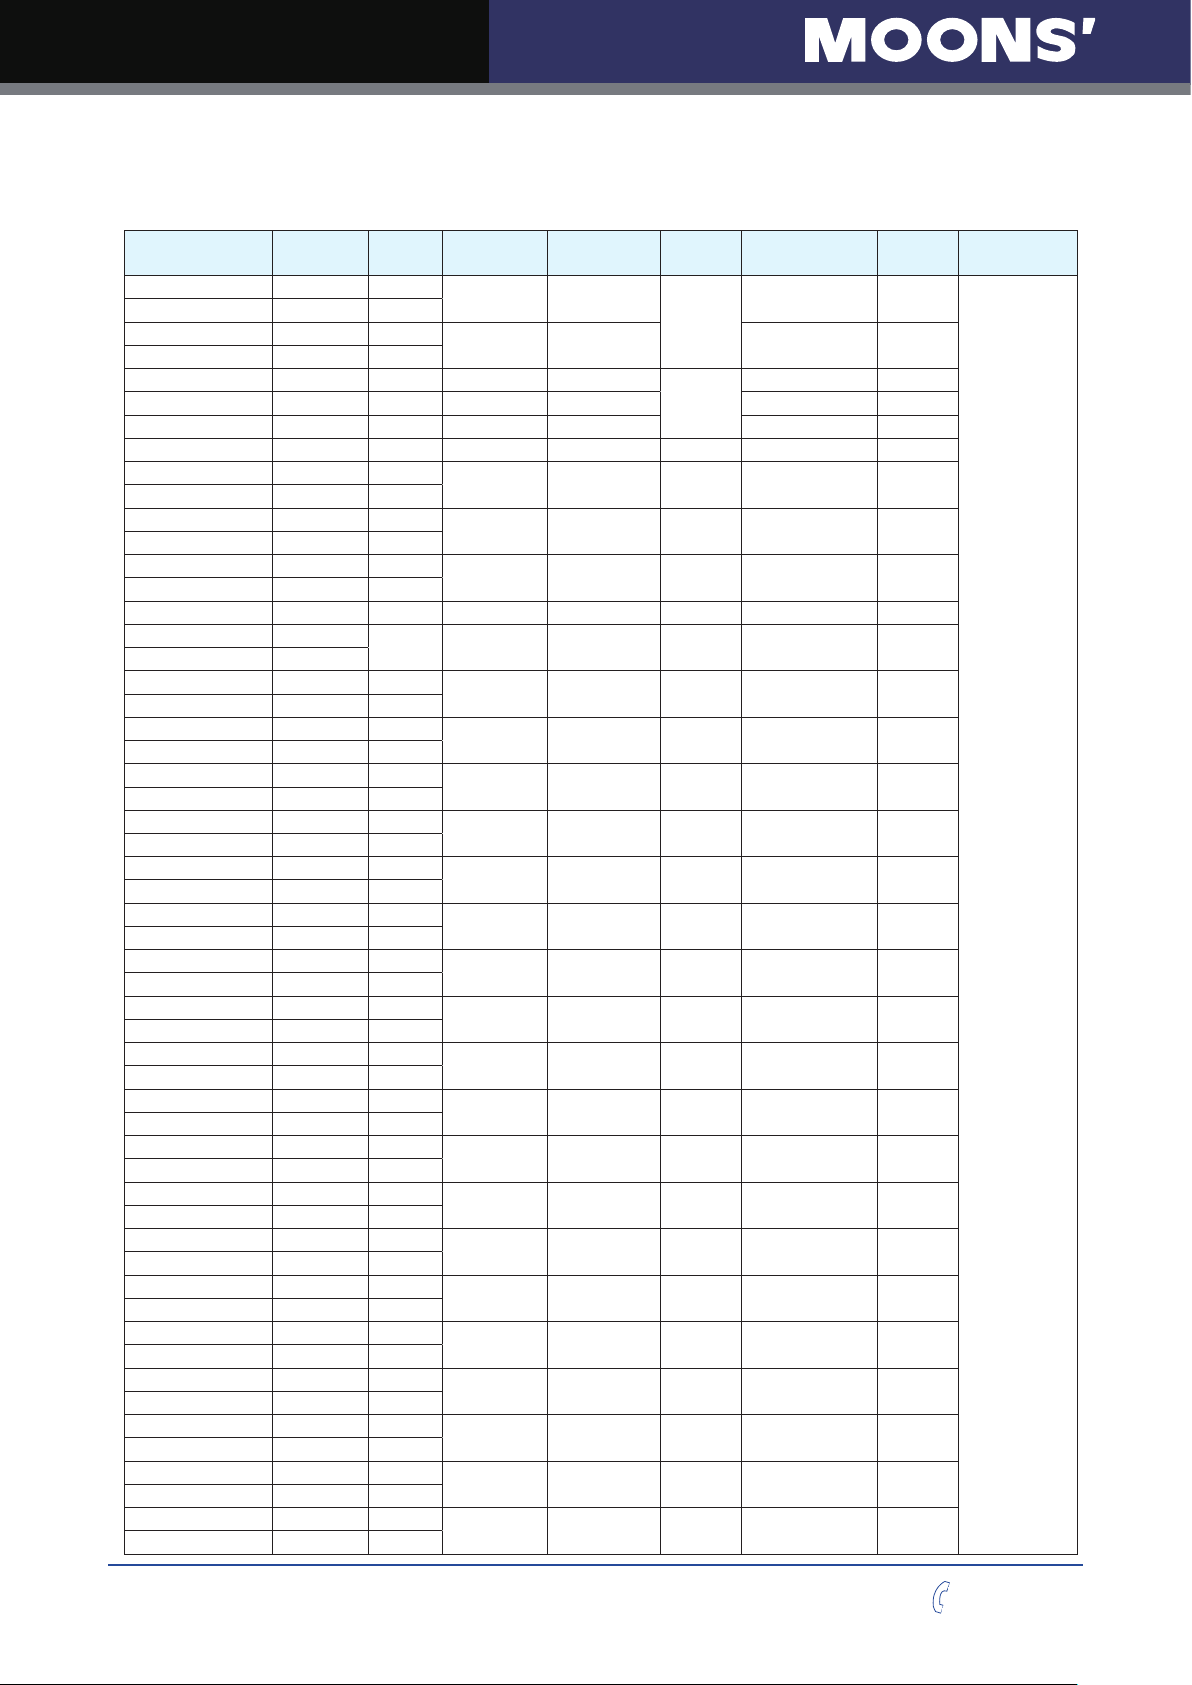
5.3 Recommended Motor
Standard type step motor
Model Features
AM8HY2050-01N Single Shaft 4
AM8HY2050-02N Double Shaft 4
AM8HY4043-01N Single Shaft 4
AM8HY4043-02N Double Shaft 4
AM11HS1008-07 Single Shaft 4 31 0.05
AM11HS3007-02 Single Shaft 4 40 0.08 12 0.15
AM11HS5008-01 Single Shaft 4 51 0.12 18 0.2
AM14HYB401-03 Single Shaft 4 40 0.2 1 20 0.21
AM17HD4452-02N Single Shaft 4
AM17HD4452-01N Double Shaft 4
AM17HD2438-02N Single Shaft
AM17HD2438-01N
AM17HD6426-06N Single Shaft 4
AM17HD6426-05N Double Shaft 4
AM17HDB410-01N Single Shaft 4 62.8 0.85 1.6 123 0.6
AM23HS0420-01 Single Shaft
AM23HS0420-02 Double Shaft
AM23HS2449-01 Single Shaft 4
AM23HS2449-02 Double Shaft 4
AM23HS3454-01 Single Shaft 4
AM23HS3454-02 Double Shaft 4
AM23HS0421-01 Single Shaft 4
AM23H
S0421-02 Double Shaft
AM23HS2450-01 Single Shaft 4
AM23HS2450-02 Double Shaft 4
AM23HS3455-01 Single Shaft 4
AM23HS3455-02 Double Shaft 4
AM23HS04A0-01 Single Shaft 4
AM23HS04A0-02 Double Shaft 4
AM23HS84A0-01 Single Shaft 4
AM23HS84A0-02 Double Shaft 4
AM23HSA4A0-01 Single Shaft 4
AM23HSA4A0-02 Double Shaft 4
AM23HS04B0-01 Single Shaft 4
AM23HS04B0AM23HS84B0-01
AM23HS84B0-02 Double Shaft 4
AM23HSA4B0-01 Single Shaft 4
AM23HSA4B0-02 Double Shaft 4
AM23HS04B0-03 Single Shaft 4
AM23HS04B0-04 Double Shaft 4
AM23HS84B0-03 Single Shaft 4
AM23HS84B0-04 Double Shaft 4
AM23HSA4B0-03 Single Shaft 4
AM23HSA4B0-04 Double Shaft 4
AM24HS2402-08N Single Shaft 4
AM24HS2402-11N Do
AM24HS5401-10N
AM24HS5401-24N Double Shaft 4
AM34HD0404-08 Single Shaft 4
AM34HD0404-09 Double Shaft 4
AM34HD1404-06 Single Shaft 4
AM34HD1404-07 Double Shaft 4
AM34HD2403-07 Single Shaft 4
AM34HD2403-08 Double Shaft 4
Double Shaft 4
ouble Shaft 4
02 D
Single Shaft 4
uble Shaft 4
Single Shaft 4
Lead
number
Length(mm)
31.5 0.015
47 0.037 4.2 0.09
34.3 0.25 1.8 38 0.23
4
4 41 0.6 2.2 135 0.42
4
39.8 0.4 1.8 57 0.28
48.3 0.5 1.8 82 0.36
54 1.2 2.2 260 0.6
76 1.8 2.2 460 1
41 0.6 4.5 135 0.42
54 1.2 4.5 260 0.6
76 1.8 4.5 460 1
39 0.82 2.2 120 0.4
55 1.5 2.2 220 0.6
77 2.3 2.2 390 1
39 0.82 4.5 120 0.4
55 1.5 4.5 220 0.6
77 2.3 4.5 390 1
39 0.82 4.5 120 0.4
55 1.5 4.5 220 0.6
77 2.3 4.5 390 1
54 1.2 4.5 450 0.83
85 2.5 4.5 900 1.4
66.5 3 7 1100 1.6
96 5 7 1850 2.7
125.5 7.1 7 2750 3.8
Holding
Torque(N.m)
Current(A)
0.5
1.6
Rotor
Inertia(g.cm2)
2 0.05
9 0.1
Mass(Kg)
Mass Dielectric
Strength
500VAC/1Minute
Rev. 1.0
11/08/2017
24
400-820-9661
Page 25
STF-R/C Hardware Manual
IP65 type motor
Model Features
AM23HS2450-03 IP65 Motor 4 61.7 1.2
AM23HS3455-05 IP65 Motor 4 83.7 1.8 460 1
AM24HS5401-44N IP65 Motor 4 94.5 2.5 900 1.4
AM34HD1404-13 IP65 Motor 4 98 5
AM34HD2403-13 IP65 Motor 4 127.5 7.1 2750 3.8
Lead
number
Length(mm)
Brake type motor
Model Features
AM17HD4452-BR01 Brake Motor 4+2 60.3 0.25
AM17HD2438-BR01 Brake Motor 4+2 65.8 0.4 57 0.43
AM17HD6426-BR01 Brake Motor 4+2 74.3 0.5 82 0.51
AM17HDB410-BR01 Brake Motor 4+2 88.8 0.85 123 0.75
AM23HS2449-BR01 Brake Motor 4+2 95 1.2
AM23HS2450-BR01 Brake Motor 4+2 95 1.2 260 0.8
AM23HS04B0-BR01 Brake Motor 4+2 80 0.82
AM23HS84B0-BR01 Brake Motor 4+2 96 1.5 220 0.8
AM23HSA4B0-BR01 Brake Motor 4+2 118 2.3 390 1.2
AM24HS2402-BR01 Brake Motor 4+2 95 1.2
AM24HS5401-BR01 Brake Motor 4+2 126 2.5 900 1.6
AM34HD0404-BR01 Brake Motor 4+2 118.5 3
AM34HD1404-BR01 Brake Motor 4+2 148 5 1850 3.3
AM34HD2403-BR01 Brake Motor 4+2 177.5 7.1 2750 4.4
Lead
number
Length(mm)
Holding
Torque(N.m)
Holding
Torque(N.m)
Current(A)
4.5
7
Current(A)
1.8
2.2
4.5
4.5
7
Rotor
Inertia(g.cm2)
260 0.6
1850 2.7
Rotor
Inertia(g.cm2)
38 0.38
260 0.8
120 0.62
450 1.03
1100 2.2
Mass(Kg)
Mass(Kg)
Mass Dielectric
Strength
500VAC/1Minute
Mass Dielectric
Strength
500VAC/1Minute
Encoder type motor
Model Features
AM17HD4452-E1000D Encoder motor 4 34.3 0.25
AM17HD2438-E1000D Encoder motor 4 39.8 0.4 57 0.28
AM17HD6426-E1000D Encoder motor 4 48.3 0.5 82 0.36
AM23HS0420-E1000D Encoder motor 4 41 0.6
AM23HS2449-E1000D Encoder motor 4 54 1.2 260 0.6
AM23HS3454-E1000D Encoder motor 4 76 1.8 460 1
AM23HS0421-E1000D Encoder motor 4 41 0.6
AM23HS2450-E1000D Encoder motor 4 54 1.2 260 0.6
AM23HS3455-E1000D Encoder motor 4 76 1.8 460 1
AM23HS5412-E1000D Encoder motor 4 111 3.2 750 1.5
AM24HS2402-E1000D Encoder motor 4 54 1.2 450 0.83
AM24HS5401-E1000D Encoder motor 4 85 2.5 900 1.4
AM34HD0404-E1000D Encoder motor 4 66.5 3
AM34HD1404-E1000D Encoder motor 4 96 5 1850 2.7
AM34HD2403-E1000D Encoder motor 4 125.5 7.1 2750 3.8
Lead
number
Length(mm)
Holding
Torque(N.m)
Current(A)
1.8
2.2
4.5
7
Rotor
Inertia(g.cm2)
38 0.23
135 0.42
135 0.42
1100 1.6
Mass(Kg)
Mass Dielectric
Strength
500VAC/1Minute
400-820-9661
25
Rev. 1.0
11/08/2017
Page 26
STF-R/C Hardware Manual
Gearbox type motor
Model Features
AM17HD4452-PG05 5 speed reducer motor 4 101.8 1.25 1.8 950 0.55
AM17HD4452-PG10 10 speed reducer motor 4 101.8 2.5 1.8 3800 0.55
AM17HD4452-PG20 20 speed reducer motor 4 114.8 5 1.8 15200 0.63
AM17HD2438-PG05 5 speed reducer motor 4 107.3 2 1.8 1425 0.6
AM17HD2438-PG10 10 speed reducer motor 4 107.3 4 1.8 5700 0.6
AM17HD2438-PG20 20 speed reducer motor 4 120.3 8 1.8 22800 0.68
AM17HD6426-PG05 5 speed reducer motor 4 115.8 2.5 1.8 2050 0.68
AM17HD6426-PG10 10 speed reducer motor 4 115.8 5 1.8 8200 0.68
AM17HD6426-PG20 20 speed reducer motor 4 128.8 10 1.8 32800 0.76
AM17HDB410-PG05 5 speed reducer motor 4 130.3 4.25 1.6 3075 0.92
AM17HDB410-PG10 10 speed reducer motor 4 130.3 8.5 1.6 12300 0.92
AM17HDB410-PG20 20 speed reducer motor 4 143.3 17 1.6 49200 1
AM23HS04B0-PG05 5 speed reducer motor 4 112.5 4.1 4.5 2625 1.23
AM23HS04B0-PG10 10 speed reducer motor 4 112.5 8.2 4.5 10500 1.23
AM23HS04B0-PG20 20 speed reducer motor 4 125.5 16.4 4.5 42000 1.44
AM23HS84B0-PG05 5 speed reducer motor 4 128.5 7.5 4.5 5375 1.43
AM23HS84B0-PG10 10 speed reducer motor 4 128.5 15 4.5 21500 1.43
AM23HS84B0-PG20 20 speed reducer motor 4 141.5 30 4.5 86000 1.64
AM23HSA4B0-PG05 5 speed reducer motor 4 150.5 11.5 4.5 9125 1.83
AM23HSA4B0-PG10 10 speed reducer motor 4 150.5 23 4.5 36500 1.83
AM23HSA4B0-PG20 20 speed reducer motor 4 163.5 46 4.5 146000 2.07
AM24HS2402-PG05 5 speed reducer motor 4 127.5 6 4.5 11250 1.66
AM24HS2402-PG10 10 speed reducer motor 4 127.5 12 4.5 45000 1.66
AM24HS2402-PG20 20 speed reducer motor 4 140.5 24 4.5 180000 1.87
AM24HS5401-PG05 5 speed reducer motor 4 158.5 12.5 4.5 22500 2.23
AM24HS5401-PG10 10 speed reducer motor 4 158.5 25 4.5 90000 2.23
AM24HS5401-PG20 20 speed reducer motor 4 171.5 50 4.5 360000 2.44
AM34HD0404-PG05 5 speed reducer motor 4 170.5 15 7 27500 3.71
AM34HD0404-PG10 10 speed reducer motor 4 170.5 30 7 110000 3.71
AM34HD0404-PG20 20 speed reducer motor 4 188.5 60 7 440000 4.21
AM34HD1404-PG05 5 speed reducer motor 4 210 25 7 46250 4.81
AM34HD1404-PG10 10 speed reducer motor 4 210 50 7 185000 4.81
AM34HD1404-PG20 20 speed reducer motor 4 218 100 7 740000 5.31
AM34HD2403-PG05 5 speed reducer motor 4 229.5 35.5 7 68750 5.91
AM34HD2403-PG10 10 speed reducer motor 4 229.5 71 7 275000 5.91
AM34HD2403-PG20 20 speed reducer motor 4 247.5 142 7 1100000 6.41
Lead
number
Length(mm)
Holding
Torque(N.m)
Current(A)
Rotor
Inertia(g.cm2)
Mass(Kg)
Mass Dielectric
Strength
500VAC/1Minute
Rev. 1.0
11/08/2017
26
400-820-9661
Page 27
STF-R/C Hardware Manual
AM8HY2050
AM8HY4043
AM11HS1008
Torque(N·m)
Torque(N·m)
AM17HD2438
Torque(mN m)
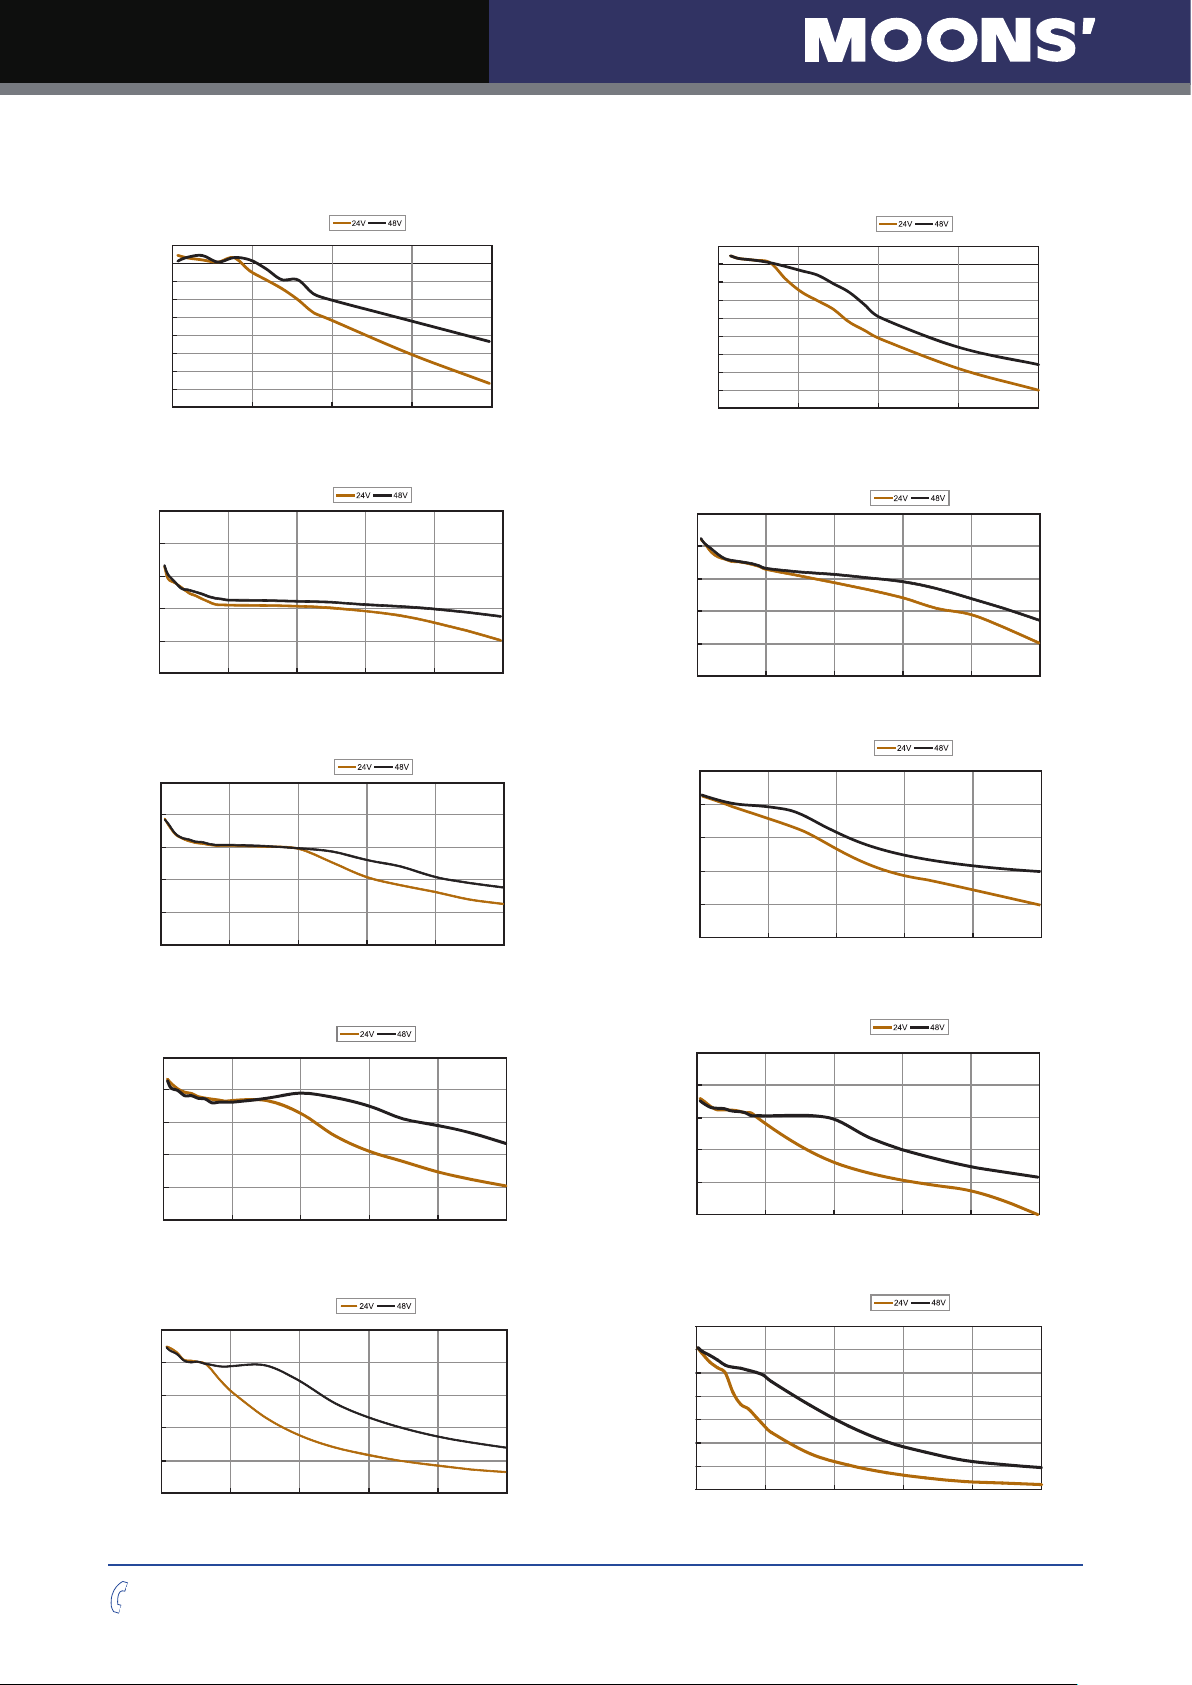
5.4 Torque Curves
Microstep: 20000 steps/rev
Current: 0.5A(Peak)
0.016
0.014
0.012
.
0.01
0.008
0.006
Torque(N m)
0.004
0.002
0
0 5 10 15 20
Speed(rps)
Microstep: 20000 steps/rev
Current: 0.5A(Peak)
0.040
0.035
0.030
.
0.025
0.020
0.015
Torque(N m)
0.010
0.005
0
0 5 10 15 20
Speed(rps)
Microstep: 20000 steps/rev
Current: 1.6A(Peak)
0.1
0.08
0.06
0.04
0.02
0
01020304050
AM11HS5008
Microstep: 20000 steps/rev
Current: 1.6A(Peak)
0.15
0.12
0.09
0.06
0.03
0
01020304050
AM17HD4452
Microstep: 20000 steps/rev
Current: 1.8A(Peak)
0.25
0.20
0.15
0.10
Torque(N·m)
0.05
0
01020304050
Speed(rps)
Speed(rps)
Speed(rps)
AM11HS3007
Microstep20000 steps/rev
Current1.6APeak
100
80
.
60
40
Torque(mN m)
20
0
01020304050
AM14HYB401
Microstep: 20000 steps/rev
Current: 1.0A(Peak)
0.15
0.12
0.09
0.06
Torque(N·m)
0.03
0
01020304050
Microstep: 20000 steps/rev
Current: 1.8A(Peak)
0.5
0.4
0.3
0.2
Torque(N·m)
0.1
0
01020304050
Speed(rps)
Speed(rps)
Speed(rps)
AM17HD6426
Microstep20000 steps/rev
Current1.8APeak
500
400
.
300
200
100
0
01020304050
Speed(rps)
400-820-9661
27
AM17HDB410
Microstep: 20000 steps/rev
Current: 1.8A(Peak)
0.7
0.6
0.5
0.4
0.3
0.2
Torque(N·m)
0.1
0
01020304050
Speed(rps)
Rev. 1.0
11/08/2017
Page 28
STF-R/C Hardware Manual
05
.
.
Torque(N m)
.
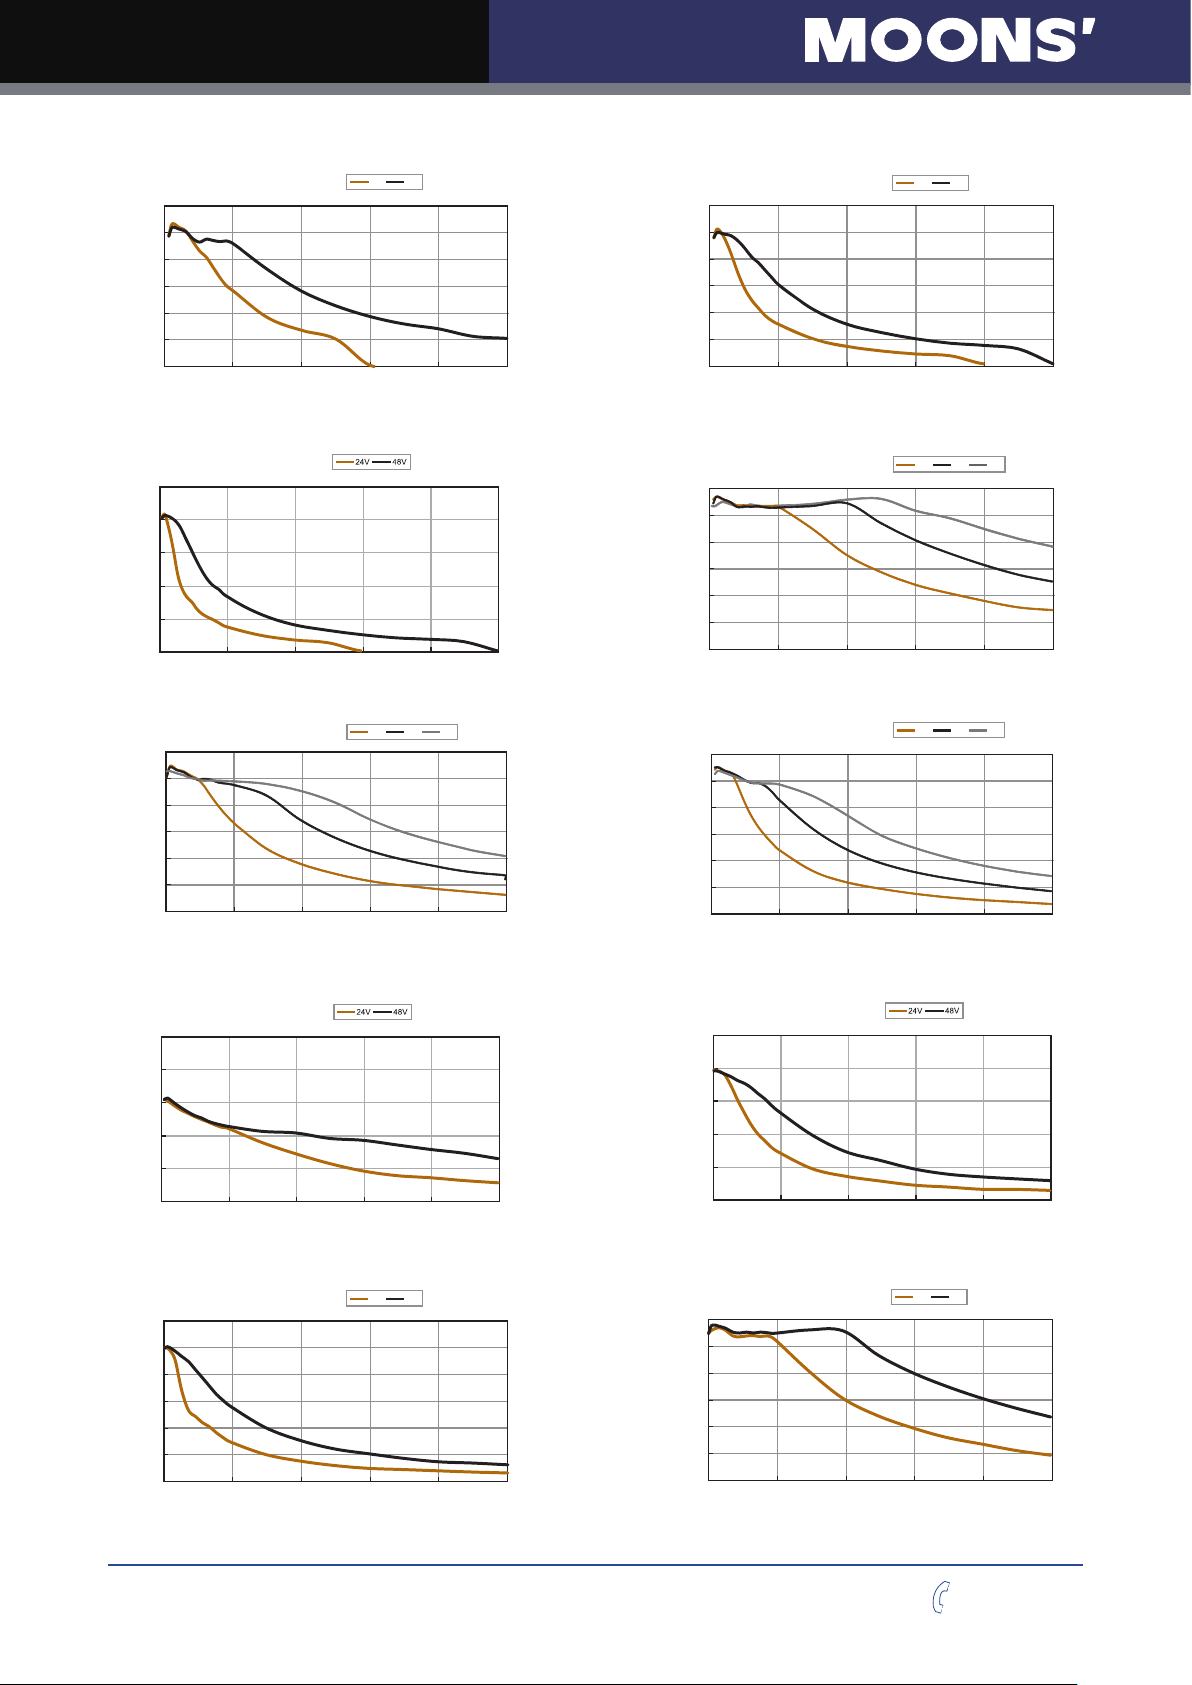
AM23HS0420
Microstep: 20000 steps/rev
Current: 2.2A(Peak)
0.6
24V
48V
0.5
m)
0.4
0.3
0.2
Torque(N
0.1
0
010203040 50
Speed(rps)
AM23HS3454
Microstep: 20000 steps/rev
Current: 2.2A(Peak)
2
1.6
.
1.2
0.8
0.4
0
01020304050
Speed(rps)
AM23HS2450
Microstep: 20000 steps/rev
Current: 4.5A(Peak)
1.2
1
m)
0.8
48V
24V
75V
0.6
0.4
Torque(N
0.2
0
010203040 50
Speed(rps)
AM23HS2449
Microstep: 20000 steps/rev
Current: 2.2A(Peak)
1.2
24V
48V
1
m)
0.8
0.6
0.4
Torque(N
0.2
0
010203040 50
Speed(rps)
AM23HS0421
Microstep: 20000 steps/rev
Current: 4.5A(Peak)
0.6
48V
24V
0.5
m)
0.4
.
0.3
0.2
Torque(N
0.1
0
010203040 50
Speed(rps)
AM23HS3455
Microstep: 20000 steps/rev
Current: 4.5A(Peak)
1.8
48V
24V
1.5
m)
.
1.2
0.9
0.6
Torque(N
0.3
0
010203040 50
Speed(rps)
75V
75V
AM23HS04A0
Microstep: 20000 steps/rev
Current: 2.2A(Peak)
1
0.8
.
0.6
0.4
Torque(N m)
0.2
0
01020304050
Speed(rps)
AM23HSA4A0
Microstep: 20000 steps/rev
Current: 2.2A(Peak)
2.4
24V
48V
2
.
1.6
1.2
0.8
Torque(N m)
0.4
0
010203040 50
Speed(rps)
AM23HS84A0
Microstep: 20000 steps/rev
Current: 2.2A(Peak)
1.5
1.2
.
0.9
0.6
Torque(N m)
0.3
0
01020304
0
Speed(rps)
AM23HS04B0
Microstep: 20000 steps/rev
Current: 4.5A(Peak)
0.6
24V
48V
0.5
.
0.4
0.3
0.2
Torque(N m)
0.1
0
010203040 50
Speed(rps)
Rev. 1.0
11/08/2017
28
400-820-9661
Page 29
STF-R/C Hardware Manual
Torque(N m)
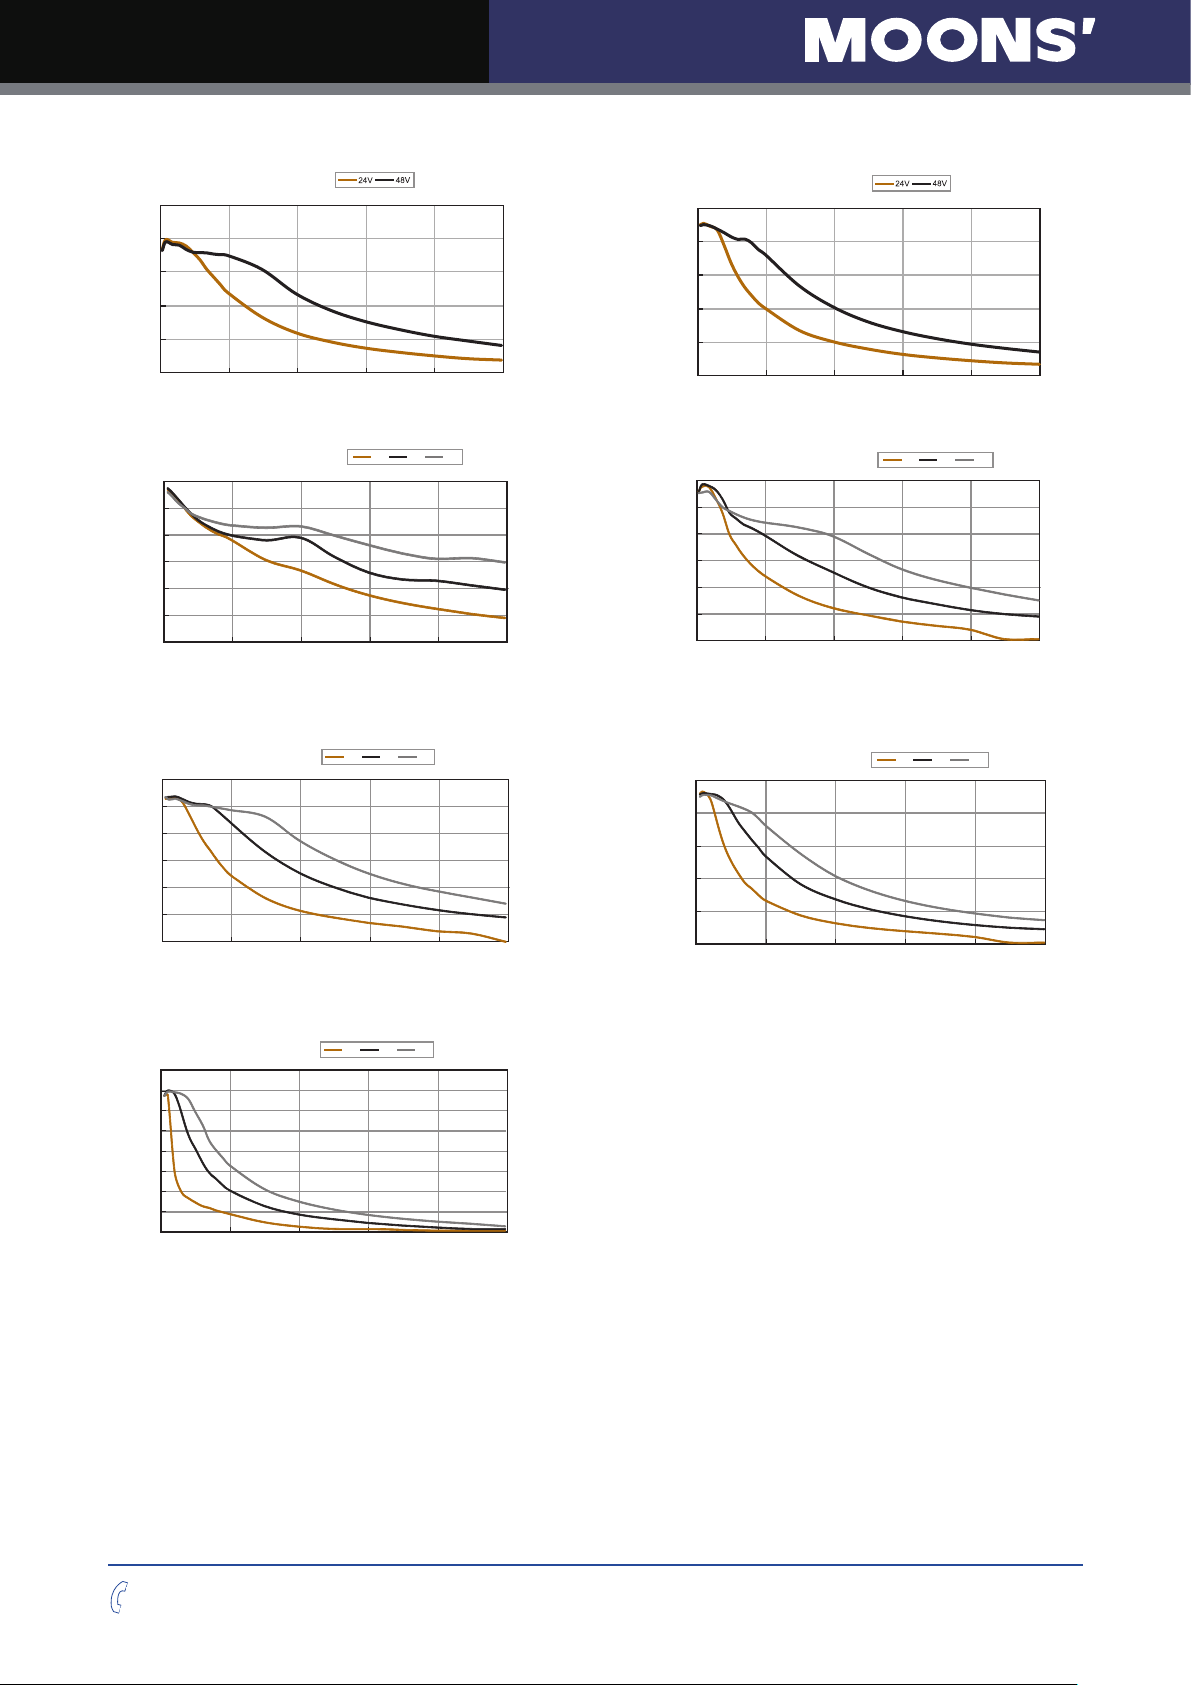
05
.
)
(euqroT
)
m N
(euqroT
AM23HS84B0
Microstep: 20000 steps/rev
Current: 4.5A(Peak)
1.5
1.2
.
0.9
0.6
0.3
0
01020304050
Speed(rps)
AM24HS2402
Microstep: 20000 steps/rev
Current: 4.5A(Peak)
1.2
24V
75V
48V
1
m)
0.8
0.6
0.4
Torque(N
0.2
0
010203040 50
Speed(rps)
AM34HD0404
Microstep: 20000 steps/rev
Current: 7.0A(Peak)
48V
24V
75V
3
2.5
m N
.
2
1.5
1
0.5
0
010203040 50
Speed(rps)
AM23HSA4B0
Microstep: 20000 steps/rev
Current: 4.5A(Peak)
2
1.6
.
1.2
0.8
Torque(N m)
0.4
0
01020304
0
Speed(rps)
AM24HS5401
Microstep: 20000 steps/rev
Current: 4.5A(Peak)
2.4
24V
75V
48V
2
m)
1.6
.
1.2
0.8
Torque(N
0.4
0
010203040 50
Speed(rps)
AM34HD1404
Microstep: 20000 steps/rev
Current: 7.0A(Peak)
5
24V
75V
48V
4
.
3
2
Torque(N m)
1
0
010203040 50
Speed(rps)
AM34HD2403
Microstep: 20000 steps/rev
Current: 7.0A(Peak)
8
48V
24V
75V
7
6
.
5
4
3
2
1
0
010203040 50
Speed(rps)
400-820-9661
29
Rev. 1.0
11/08/2017
Page 30
STF-R/C Hardware Manual
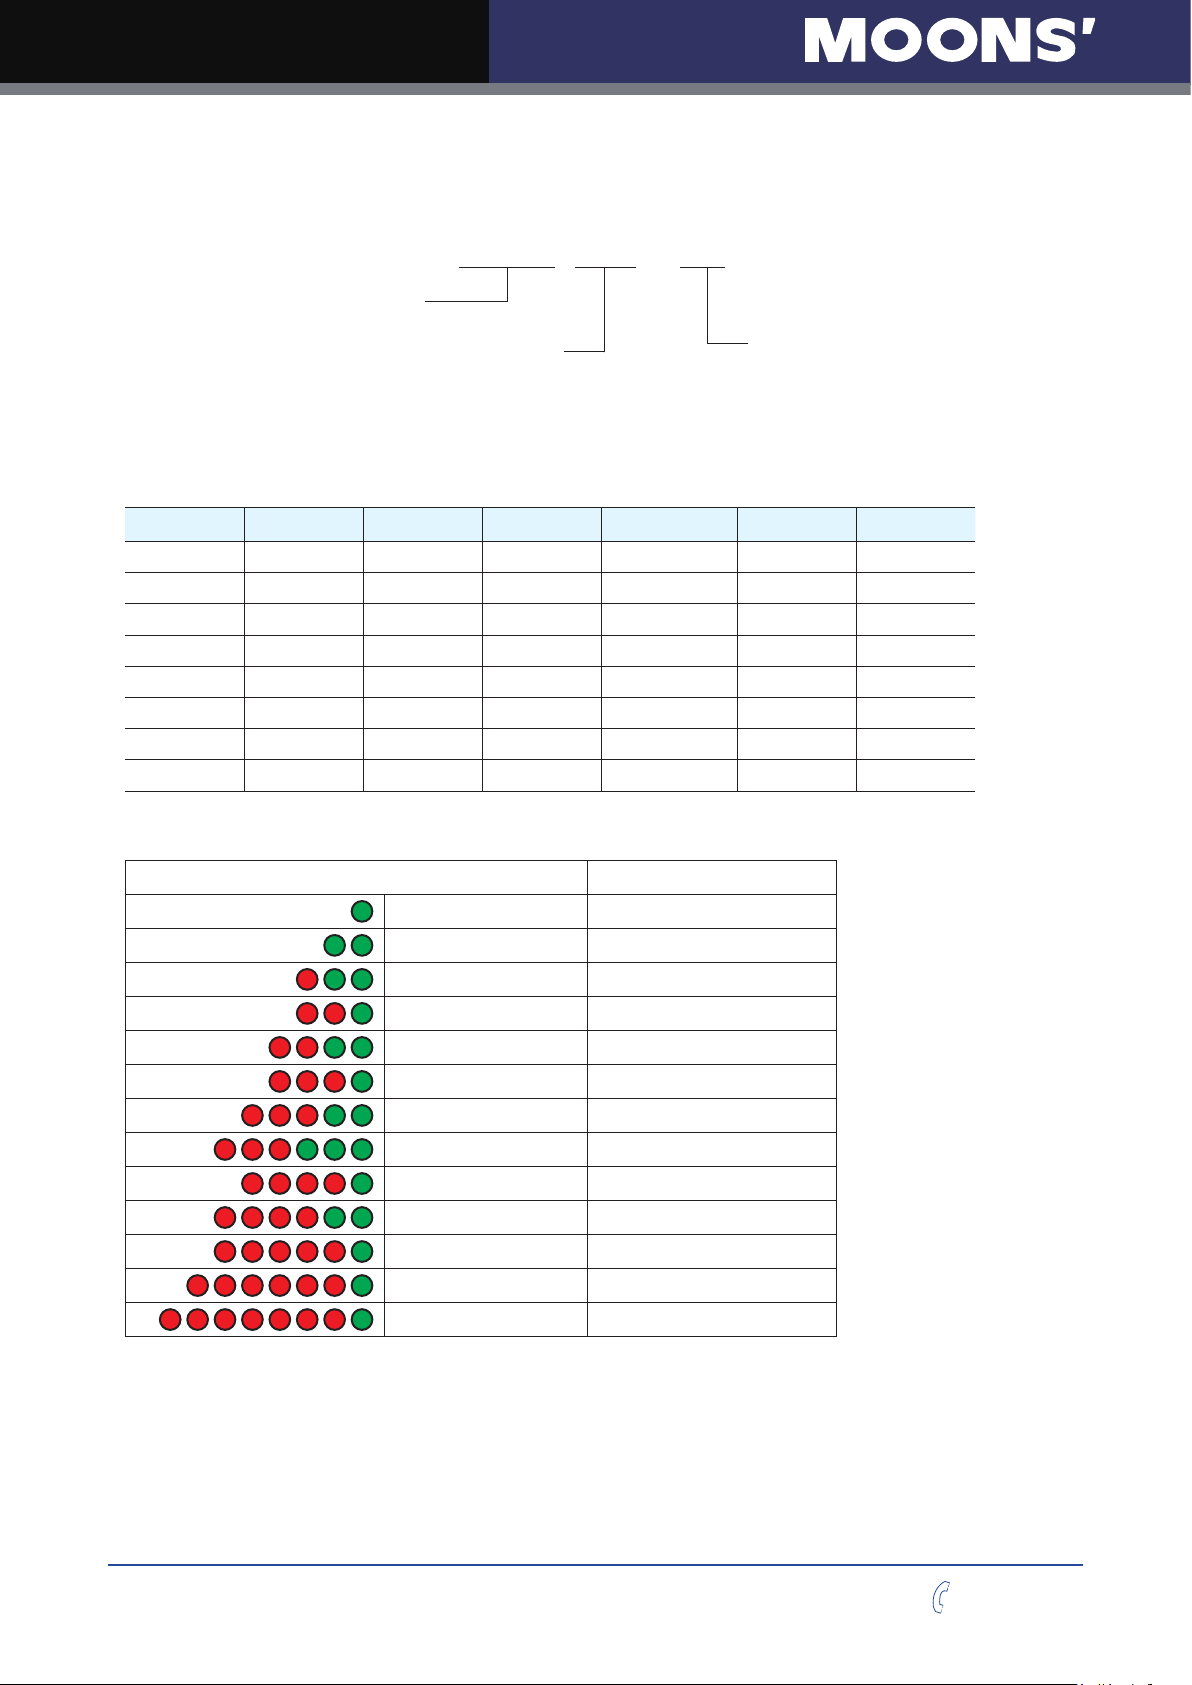
5.5 Numbering System
STF Series
STF 05 - R
Output Current(peak-of-sine)
03 = 3A(Peak)
05 = 5A(Peak)
06 = 6A(Peak)
10 = 10A(Peak)
Communication
R = RS-485
C = CANopen
5.6 Ordering Information
Model Current Voltage RS-485 Modbus/RTU CANopen Q Program
STF03-R 0.1 - 3.0 A 12 - 48 VDC
STF05-R 0.1 - 5.0 A 24 - 48 VDC
STF06-R 0.1 - 6.0 A 12 - 48 VDC
STF10-R 0.1 - 10.0 A 24 - 70 VDC
STF03-C 0.1 - 3.0 A 12 - 48 VDC
STF05-C 0.1 - 5.0 A 24 - 48 VDC
STF06-C 0.1 - 6.0 A 12 - 48 VDC
STF10-C 0.1 - 10.0 A 24 - 70 VDC
√ √
√ √
√ √
√ √
√ √
√ √
√ √
√ √
5.7 Alarm Code
Code Error
solid green no alarm,motor disabled
ashing green no alarm,motor enabled
1 red, 2 green move while disabled
2 red, 1 green CCW limit
2 red, 2 green CW limit
3 red, 1 green drive over temperature
3 red, 2 green internal voltage bad
3 red, 3 green blank Q segment
4 red, 1 green over voltage
4 red, 2 green under voltage
5 red, 1 green over current
6 red, 1 green open motor winding
7 red, 1 green communication error
√
√
√
√
NOTE: Items in bold italic represent Drive Faults, which automatically disable the motor.
Rev. 1.0
11/08/2017
30
400-820-9661
Page 31
STF-R/C Hardware Manual
L
L
8 1
8 1
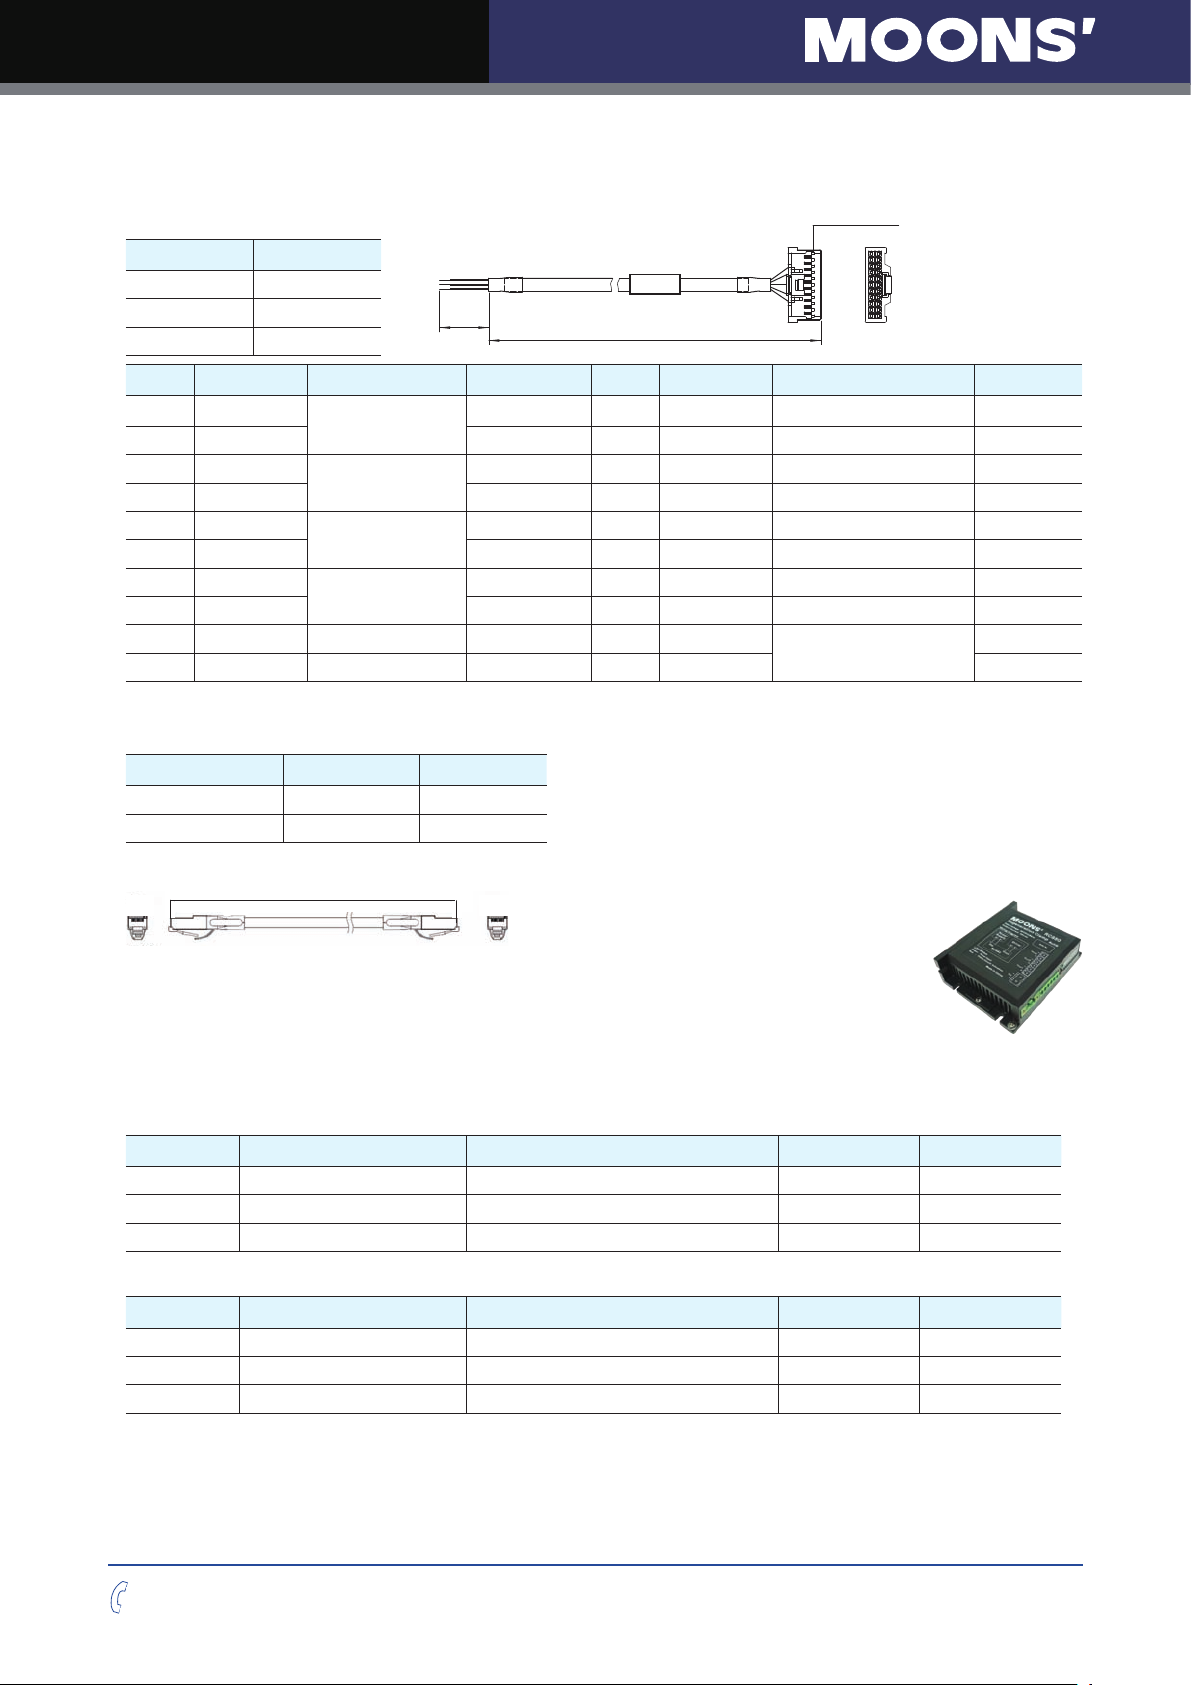
6 Accessories (Sold Separately)
I/O Cable
P/N Length
1015-030 0.3m
1015-100 1m
1015-200 2m
L
Housing: 501646-2000(Molex)
Crimp: 501648-1000(Molex)
19 20
150±5
J1
2
Pin No. Assignment Description Color Pin No. Assignment Description Color
1 X1+
2 X1- Blue/Black 12 X8 X8 Digital Input Green
3 X2+
4 X2- Green/Black 14 XCOM X5-X8 Digital Input COM Red
5 X3+
6 X3- Yellow/Black 16 Y2 Y2 Digital Output Gray
7 X4+
8 X4- Orange/Black 18 YCOM Y1-Y3 Digital Output COM Black
9 X5 X5 Digital Input Blue 19 Y4+
10 X6 X6 Digital Input Purple 20 Y4- Purple/Black
X1 Digital Input
X2 Digital Input
X3 Digital Input
X4 Digital Input
RS-485/CANopen Communication Cable
Common Type Shielded Type Length
2012-030 * 2013-030 0.3m
2012-300 2013-300 3m
* 2012-030 is included in the drive package.
Blue/White 11 X7 X7 Digital Input Yellow
Green/White 13 SHIELD Shield Shield
Yellow/White 15 Y1 Y1 Digital Output Brown
Orange/White 17 Y3 Y3 Digital Output White
Y4 Digital Output
Purple/White
RC-880 Regeneration Clamp
RC-880 is used to limit increase in power supply
voltage when the motor is decelerating under load.
This is commonly referred to as "regeneration".
RC-880 can clamp the regeneration and prevent
the power supply and/or drive being damaged or
destroyed. Connect the RC-880 between the power
supply and the drive.
Max. Supply Voltage: 80V
Max. Output Current: 8A(rms)
Continuous Power: 50W
Mating Connector (included in drive package)
STF05/10
Part Description Part Number Vendor Qty
J1 Power & Motor Connector 2EDGK-5.08-06P-13-1000AH DEGSON 1
J2 I/O Connector Housing 501646-2000 Molex 1
J2 I/O Connector Crimp 501648-1000 Molex 20
STF03/06
Part Description Part Number Vendor Qty
J1 Power & Motor Connector BCP-381-6 BK Phoenix 1
J2 I/O Connector Housing 501646-2000 Molex 1
J2 I/O Connector Crimp 501648-1000 Molex 20
400-820-9661
31
Rev. 1.0
11/08/2017
Page 32
STF-R/C Hardware Manual
MOONS’Headquarter
168 Mingjia Road, Minhang District, Shanghai 201107,
P.R. China
Tel: +86 (0)21 52634688
Fax:+86 (0)21 52634098
Domestic Offices
Shenzhen
Room 2209, 22/F, Kerry Center, 2008 Renminnan Road,
Luohu District, Shenzhen 518001, P.R. China
Tel: +86 (0)755 25472080
Fax:+86 (0)755 25472081
North America Company
MOONS’INDUSTRIES (AMERICA), INC.
1113 North Prospect Avenue, Itasca, IL 60143 USA
Tel: +1 630 8335940
Fax: +1 630 8335946
APPLIED MOTION PRODUCTS, INC.
404 Westridge Dr. Watsonville, CA 95076, USA
Tel: +1 831 7616555
Fax:+1 831 7616544
LIN ENGINEERING, INC.
16245 Vineyard Blvd., Morgan Hill, CA 95037
Tel: +1 408 9190200
Fax:+1 408 9190201
European Company
MOONS’ INDUSTRIES (EUROPE) S.R.L.
Via Torri Bianche n.1 20871 Vimercate(MB) Italy
Tel: +39 039 6260521
Fax: +39 039 9631409
Japan Company
MOONS’INDUSTRIES JAPAN CO., LTD.
Room 601, 6F, Shin Yokohama Koushin Building,
2-12-1, Shin-Yokohama, Kohoku-ku, Yokohama,
Kanagawa, 222-0033, Janpan
Tel: +81 (0)45 4755788
Fax: +81 (0)45 4755787
South-East company
MOONS’INDUSTRIES (SOUTH-EAST ASIA) PTE. LTD.
33 Ubi Avenue 3 #08-23 Vertex Singapore 408868
Tel: +65 66341198
Fax: +65 66341138
Nanjing
Room 1101-1102, Building 2,New Town Development
Center,No.126 Tianyuan Road ,Moling Street,
Jiangning District,Nanjing 211106, P.R. China
Tel: +86 (0)25 52785841
Fax:+86 (0)25 52785485
Qingdao
Room 1012, Zhuoyue Tower, No.16 Fengcheng Road,
Shibei District, Qingdao 26000, P.R. China
Tel: +86 (0)532 80969935
Fax:+86 (0)532 80919938
Beijing
Room 816, Tower B, China Electronics Plaza, 3 Danling
Street, Haidian District, Beijing 100080, P.R. China
Tel: +86 (0)10 58753312
Fax:+86 (0)10 58752279
Wuhan
Room 3001, World Trade Tower, 686 Jiefang Avenue,
Jianghan District, Wuhan 430022, P.R. China
Tel: +86 (0)27 85448742
Fax:+86 (0)27 85448355
Chengdu
Room 1917, Western Tower, 19, 4th Section of South People
Road, Wuhou District, Chengdu 610041, P.R. China
Tel: +86 (0)28 85268102
Fax:+86 (0)28 85268103
Xi’an
Room 1006, Tower D, Wangzuo International City,
1 Tangyan Road, Xi’an 710065, P.R. China
Tel: +86 (0)29 81870400
Fax:+86 (0)29 81870340
Ningbo
Room 309, Tower B, Taifu Plaza, 565 Jiangjia Road,
Jiangdong District, Ningbo, 315040, P.R. China
Tel: +86 (0)574 87052739
Fax:+86 (0)574 87052365
Guangzhou
Room 4006, Tower B, China Shine Plaza, 9 Linhe Xi Road,
Tianhe District, Guangzhou 510610, P.R. China
Tel: +86 (0)20 38010153
Fax:+86 (0)20 38103661
MOONS’International Trading Company
4/F, Building 30, 69 Guiqing Road, Cao He Jin Hi-Tech
Park, Shanghai 200233, P.R. China
Tel: +86 (0)21 64952755
Fax:+86 (0)21 64951993
7 Contacting MOONS’
Service Center
+86-400-820-9661
Rev. 1.0
11/08/2017
32
400-820-9661
 Loading...