

Page 1
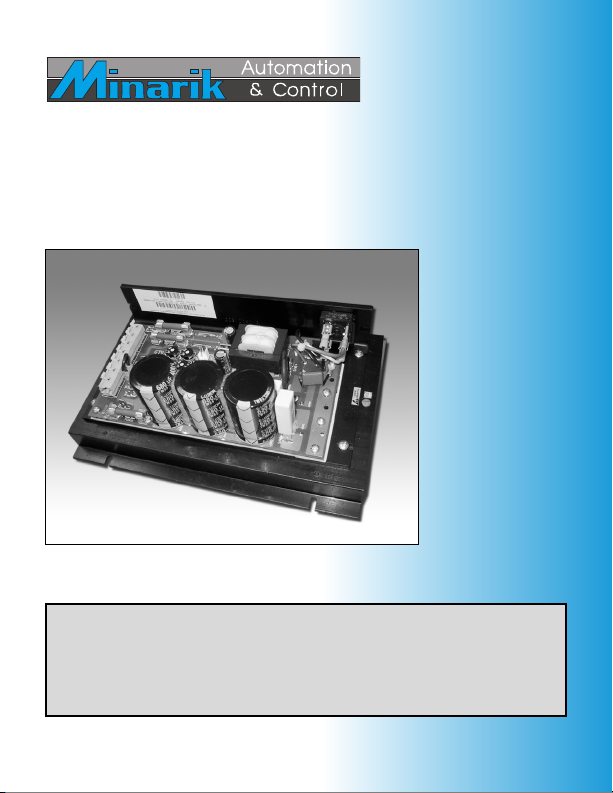
XL3300A
User’s Manual
Pulse-Width Modulated,
Adjustable Speed, Chassis Drive for
DC Brush Motors
Page 2
Copyright © 2002 by
Minarik Corporation
All rights reserved. No part of this manual may be reproduced or transmitted in any
form without written permission from Minarik Corporation. The information and
technical data in this manual are subject to change without notice. Minarik
Corporation and its Divisions make no warranty of any kind with respect to this
material, including, but not limited to, the implied warranties of its merchantability
and fitness for a given purpose. Minarik Corporation and its Divisions assume no
responsibility for any errors that may appear in this manual and make no
commitment to update or to keep current the information in this manual.
MVD102302
Printed in the United States of America.
Page 3
Safety Warnings
• This symbol denotes an important safety tip or warning.
Please read these instructions carefully before performing
any of the procedures contained in this manual.
• DO NOT INSTALL, REMOVE, OR REWIRE THIS EQUIPMENT
WITH POWER APPLIED. Have a qualified electrical technician
install, adjust and service this equipment. Follow the National
Electrical Code and all other applicable electrical and safety
codes, including the provisions of the Occupational Safety and
Health Act (OSHA), when installing equipment.
• Reduce the chance of an electrical fire, shock, or explosion by
proper grounding, over-current protection, thermal protection,
and enclosure. Follow sound maintenance procedures.
SHOCKAVOID
OID
ON
It is possible for a drive to run at full speed as a result of
a component failure. Minarik strongly recommends the
installation of a master switch in the main power input to stop
the drive in an emergency.
Circuit potentials are at 115 VAC or 230 VAC above earth
ground. Avoid direct contact with the printed circuit board or
with circuit elements to prevent the risk of serious injury or
fatality. Use a non-metallic screwdriver for adjusting the
calibration trimpots. Use approved personal protective
equipment and insulated tools if working on this drive with
power applied.
i
TI
Page 4
ii
Contents
Safety Warnings i
Specifications 1
Dimensions 2
PC Board Layout 3
Installation 4
Mounting . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .4
Wiring . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .6
Shielding guidelines . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .7
Connections . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .8
Cage-clamp terminal block . . . . . . . . . . . . . . . . . . . . . . . . . . . . .8
Field output . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .10
Speed adjust potentiometer . . . . . . . . . . . . . . . . . . . . . . . . . . . .11
Fusing . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .12
Voltage Follower . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .13
Operation 14
Before applying power . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .14
Startup . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .16
Diagnostic LEDs . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .16
Starting and Stopping Methods . . . . . . . . . . . . . . . . . . . . . . . . . . .17
Calibration 22
Minimum Speed (MIN SPD) . . . . . . . . . . . . . . . . . . . . . . . . . . . . .24
Maximum Speed (MAX SPD) . . . . . . . . . . . . . . . . . . . . . . . . . . . .24
Torque Limit (TORQ LIMIT) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .25
Acceleration (ACCEL) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .26
Deceleration (DECEL) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .27
IR Compensation (IR COMP) . . . . . . . . . . . . . . . . . . . . . . . . . . . .28
JOG . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .29
Calibration with low voltage DC motors . . . . . . . . . . . . . . . . . . . . .30
Page 5
iii
Table 1. Field Output Connections . . . . . . . . . . . . . . . . . . . . . . . . . . .10
Table 2. Recommended Dynamic Brake Resistor Sizes . . . . . . . . . . .21
Table 3. Replacement Parts . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .43
Table 4. AC Line Filters . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .45
Tables
Application Notes 31
Multiple Fixed Speeds . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .31
Adjustable Speeds using Potentiometers in Series . . . . . . . . . . . .32
Independent Adjustable Speeds . . . . . . . . . . . . . . . . . . . . . . . . . .33
Leader-Follower Application . . . . . . . . . . . . . . . . . . . . . . . . . . . . .34
Single Speed Potentiometer Control of
Multiple Drives . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .35
Reversing . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .36
Reversing with a DLC600 Controller . . . . . . . . . . . . . . . . . . . . . . .37
Troubleshooting 38
Before applying power . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .38
Block Diagrams 42
Replacement Parts 43
Certificate of Compliance 44
AC Line Filters . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .45
Unconditional Warranty inside back cover
Page 6
Figure 1. XL3300A Dimensions . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .2
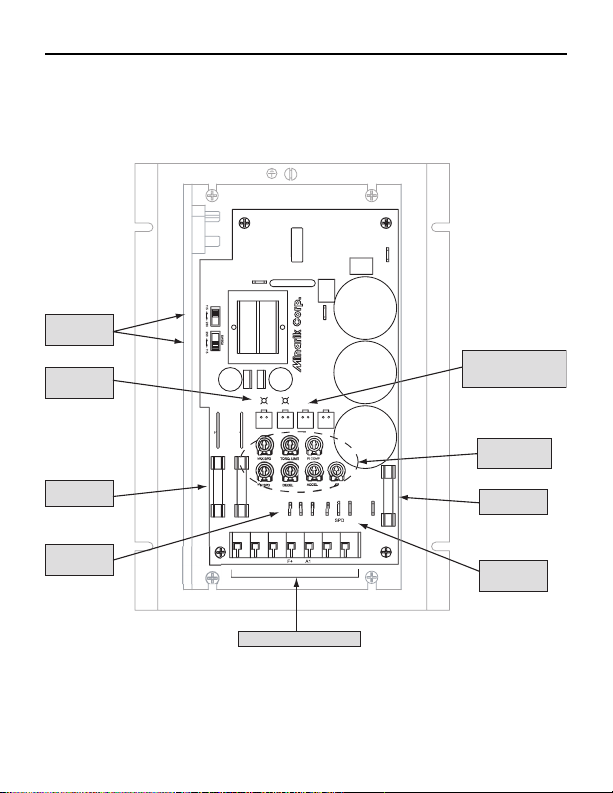
Figure 2. XL3300A PC Board Layout . . . . . . . . . . . . . . . . . . . . . . . . .3
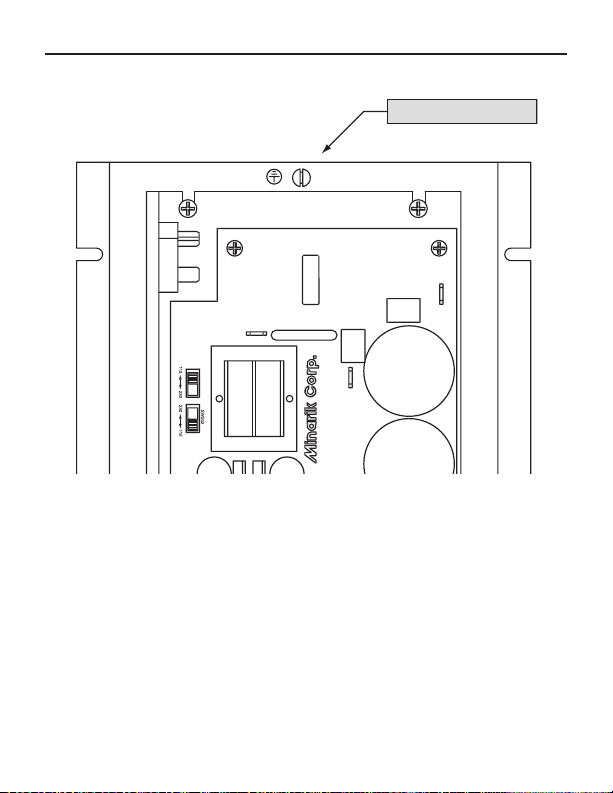
Figure 3. Earth Ground Screw . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .5
Figure 4. Cage-Clamp Terminal Block . . . . . . . . . . . . . . . . . . . . . . . . .8
Figure 5. XL3300A Connections . . . . . . . . . . . . . . . . . . . . . . . . . . . . .9
Figure 6. Speed Adjust Potentiometer . . . . . . . . . . . . . . . . . . . . . . . .11
Figure 7. Voltage Follower Connections . . . . . . . . . . . . . . . . . . . . . .13
Figure 8. Voltage Selector Switches . . . . . . . . . . . . . . . . . . . . . . . . .15
Figure 9. Inhibit Pins . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .18
Figure 10. Run/Decelerate to Minimum Speed Switch . . . . . . . . . . . .19
Figure 11. Run/Decelerate to Zero Speed Switch . . . . . . . . . . . . . . .20
Figure 12. Calibration Trimpot Layout . . . . . . . . . . . . . . . . . . . . . . . .23
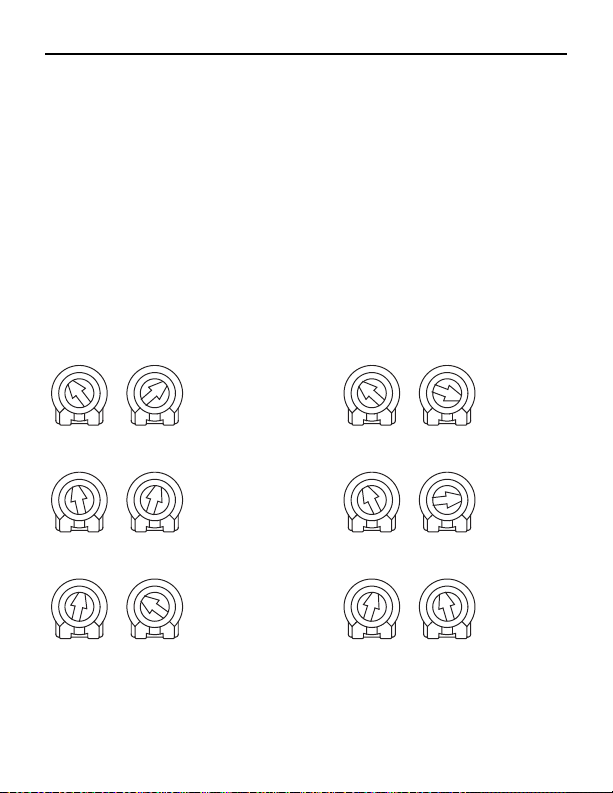
Figure 13. XL3300A TORQ. LIMIT and IR COMP Settings . . . . . . . .29
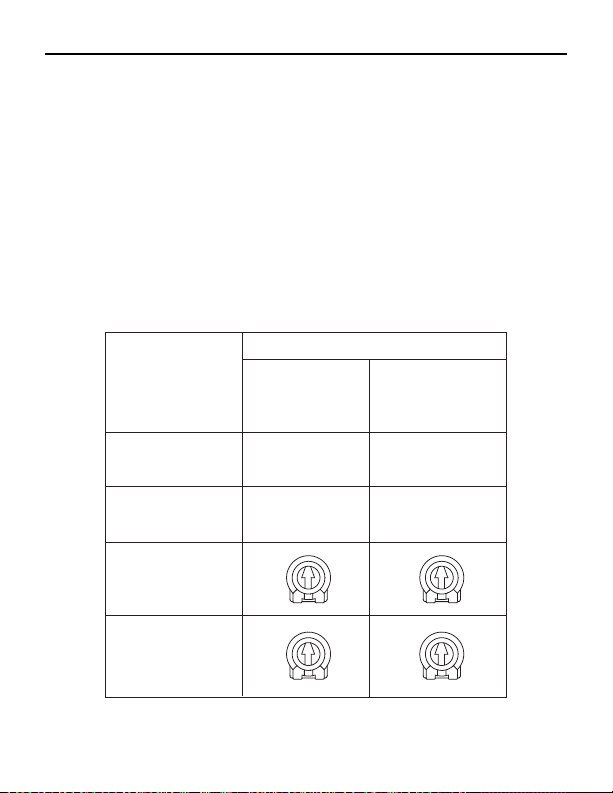
Figure 14. XL3300A MAX SPD Settings for Low Voltage DC Motors .30
Figure 15. Multiple Fixed Speeds . . . . . . . . . . . . . . . . . . . . . . . . . . .31
Figure 16. Adjustable Fixed Speeds Using Potentiometers in Series .32
Figure 17. Independent Adjustable Speeds . . . . . . . . . . . . . . . . . . . .33
Figure 18. Independent Forward and Reverse Speeds . . . . . . . . . . . .34
Figure 19. Single Speed Potentiometer Control of Multiple Drives . . .35
Figure 20. Independent Forward and Reverse Speeds . . . . . . . . . . . .36
Figure 21. Independent Forward and Reverse Speeds . . . . . . . . . . . .37
Figure 22. XL3300A Block Diagram . . . . . . . . . . . . . . . . . . . . . . . . .42
iv
Illustrations
Page 7
1
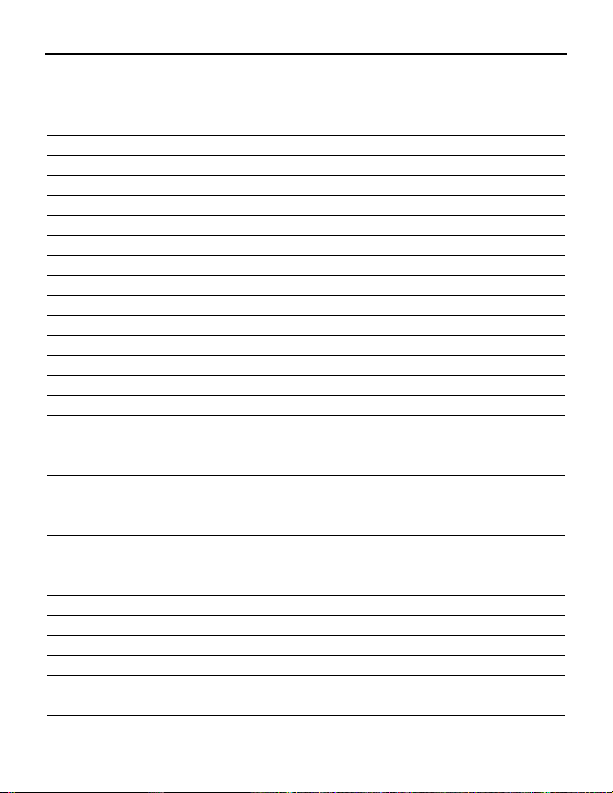
Specifications
Type open chassis
AC Line Voltage 115 VAC / 230 vac, ±10%, 50/60 Hz, single phase
Line Fuse Rating 25A, fast acting
Horsepower Range @ 130 VDC Output 1/4 - 1 1/2 HP
Horsepower Range @ 240 VDC Output 1/4 - 3 HP
Maximum Armature Voltage Range @ 115 VAC Input 45 - 130 VDC
Maximum Armature Voltage Range @ 230 VAC Input 45 - 260 VDC
Minimum Speed Adjustment Range @ 115 VAC Input 0 - 120 VDC
Minimum Speed Adjustment Range @ 230 VAC Input 0 - 120 VDC
Maximum Armature Current 13 ADC
Field Voltage @ 115 VAC Input 50 VDC / 100 VDC
Field Voltage @ 230 VAC Input 100 VDC / 200 VDC
Maximum Field Current 1 ADC
Form Factor 1.05
Acceleration Time Range (no load)
for 0 - 130 VDC Armature Voltage Range 1 - 9 seconds
for 0 - 240 VDC Armature Voltage Range 1 - 15 seconds
Deceleration Time Range (no load)
for 0 - 130 VDC Armature Voltage Range 1 - 10 seconds
for 0 - 240 VDC Armature Voltage Range 1 - 18 seconds
Analog Input Voltage Range (isolated signal; S1 to S2)
for 0 - 130 VDC Armature Voltage Range 0 - 2.5 VDC
for 0 - 240 VDC Armature Voltage Range 0 - 5.0 VDC
Speed Adjust Potentiometer 10K ohms
Approximate Input Impedance (from S1 to S2) 50K ohms
Speed Regulation (at base speed) 0.5%
Ambient Operating Temperature Range 10º - 40ºC
Vibration 0.5G max. (0 - 50 Hz)
0.1G max. (above 50 Hz)
.
Page 8
2
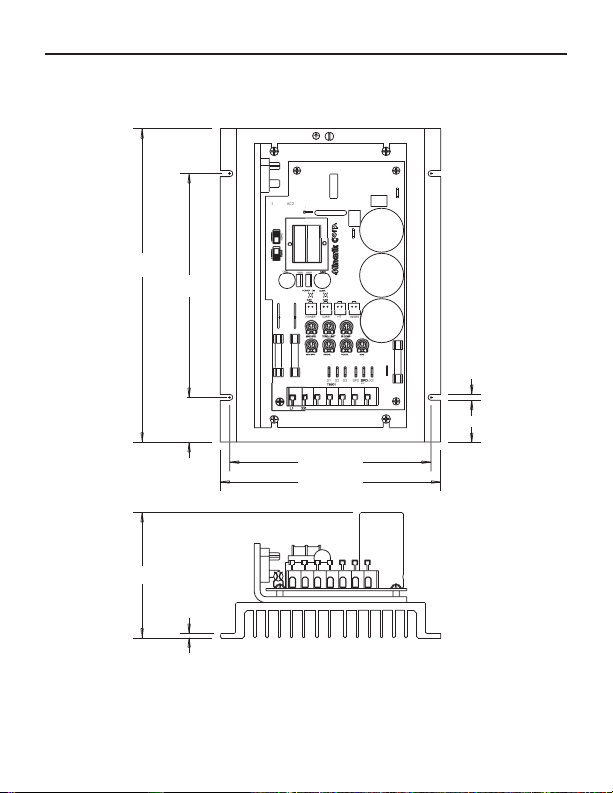
ALL DIMENSIONS IN INCHES [MILLIMETERS]
MOUNTING SLOTS 0.19 X 3.4 [5 X 9]
Dimensions
]
]
]
]
]
]
]
C
BR
BR-
US
503
US
PS1
S
S4
PS3
T
5
C507
C506
C505
501
501
Figure 1. XL3300A Dimensions
+
A
B
TH
R
9.78 [248
.00 [178
1.39 [35
LIMI
PS2
P
11
6.30 [160
6.90 [175
.92 [99
R
-B
0.19 [5
Page 9
3
PC Board Layout
Dimensions
501
-
JOG
SPD
C505
C506
C507
S2
S3
501
S1
1
PS3
S4
+15
CURR
502
R
501
PS1
S2
C504
CURR
R
C501
ON
C502
501
C502
S
1
US
503
US
BR-
BR+
C1
Figure 2. XL3300A PC Board Layout
R
-B
R
2-PIN CONNECTORS
(POWER, CURR, and +15
used on future drives).
CALIBRATION
TRIMMER
POTENTIOMETERS
FUSE
HOLDERS
A2F
SPD, PD IN,
and JOG
TERMINALS
VOLTAGE
SELECTION
SWITCHES
"POWER ON"
and "CURRENT
LIMIT" LEDs
FUSE
HOLDERS
SPEED ADJUST
POTENTIOMETER
TERMINALS
AC2A
+B
TH501
T
W50
I
I
POWE
P
P
IL
IL
POWE
TB
115230L
CAGE-CLAMP TERMINAL BLOCK
Page 10
4
• Drive components are sensitive to electrostatic fields. Avoid
direct contact with the circuit board. Hold drive by the chassis
only.
• Protect the drive from dirt, moisture, and accidental contact.
• Provide sufficient room for access to the terminal block and
calibration trimpots. The minimum enclosure size for the
XL3300A is six cubic feet.
• Mount the drive away from heat sources. Operate the drive
within the specified ambient operating temperature range.
• Prevent loose connections by avoiding excessive vibration of the
drive.
• Mount drive with its board in either a horizontal or vertical plane.
Four 0.19 inch (5 mm) wide slots in the chassis accept #8 pan
head screws.
• Connect earth ground to the green earth ground screw attached
to the heat sink. See Figure 3 (page 5) for the earth ground
screw location.
Warning
Do not install, rewire, or remove this control with input
power applied. Doing so may cause fire or serious injury.
Make sure you have read and understood the Safety
Warnings on page i before attempting installation.
Mounting
Installation
Page 11
5Installation
501
501
C506
C507
C504
C501IC502
501
C502
S
1
US
503
US
BR-
BR+
C1
EARTH GROUND SCREW
Figure 3. Earth Ground Screw
AC2A
+B
TH
T
W50
I
R
R
-B
Page 12
6 Installation
Warning
Do not install, remove, or rewire this equipment with power
applied. Failure to heed this warning may result in fire,
explosion, or serious injury.
Circuit potentials are at 115 or 230 VAC above ground. To
prevent the risk of injury or fatality, avoid direct contact with
the printed circuit board or with circuit elements.
Do not disconnect any of the motor leads from the drive
unless power is removed and the drive is disabled. Opening
any one motor lead may destroy the drive.
Wiring
• Use 18 AWG wire for speed adjust potentiometer wiring. Use 16
AWG wire for field (F1, F2) wiring. Use 14 AWG wire for AC line
(L1, L2) and motor (A1, A2) wiring.
Page 13
7Installation
Shielding guidelines
As a general rule, Minarik recommends shielding of all conductors.
If it is not practical to shield power conductors, Minarik
recommends shielding all logic-level leads. If shielding logic leads
is not practical, the user should twist all logic leads with themselves
to minimize induced noise.
It may be necessary to earth ground the shielded cable. If noise is
produced by devices other than the drive, ground the shield at the
drive end. If noise is generated by a device on the drive, ground
the shield at the end away from the drive. Do not ground both ends
of the shield.
If the drive continues to pick up noise after grounding the shield, it
may be necessary to add AC line filtering devices, or to mount the
drive in a less noisy environment.
Warning
Under no circumstances should power and logic leads be
bundled together. Induced voltage can cause unpredictable
behavior in any electronic device, including motor controls.
Page 14
8 Installation
Connections
Cage-clamp terminal block
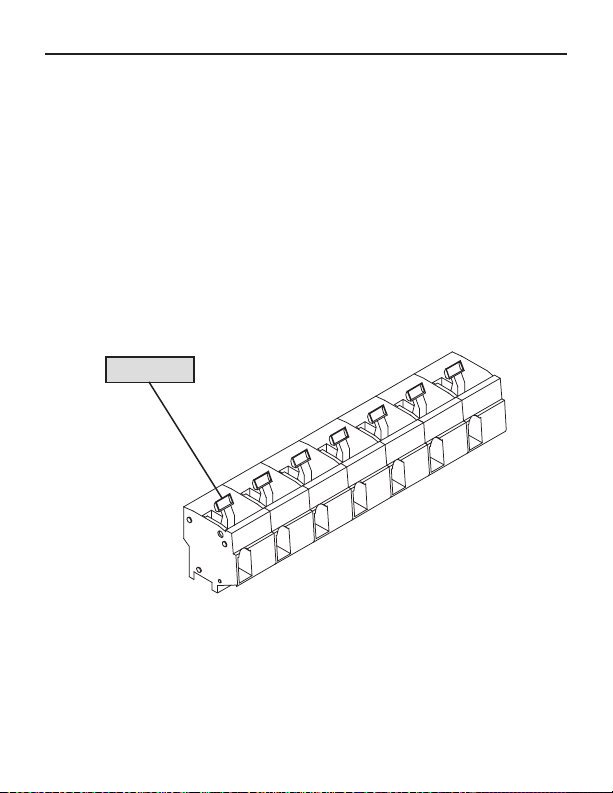
XL3300A connections are made to a cage-clamp terminal block
(Figure 4). To insert a wire into the terminal block, press down on
the lever arm using a small screwdrive. Insert stripped wire into
the large opening in front of the terminal block. Release the lever
arm to clamp the wire.
Figure 4. Cage-Clamp Terminal Block
LEVER ARM
Page 15
9Installation
501
5230
30
C
E
T
OR
JOG TRIMMER P
OT
D
r
.
r
.
o
.
D
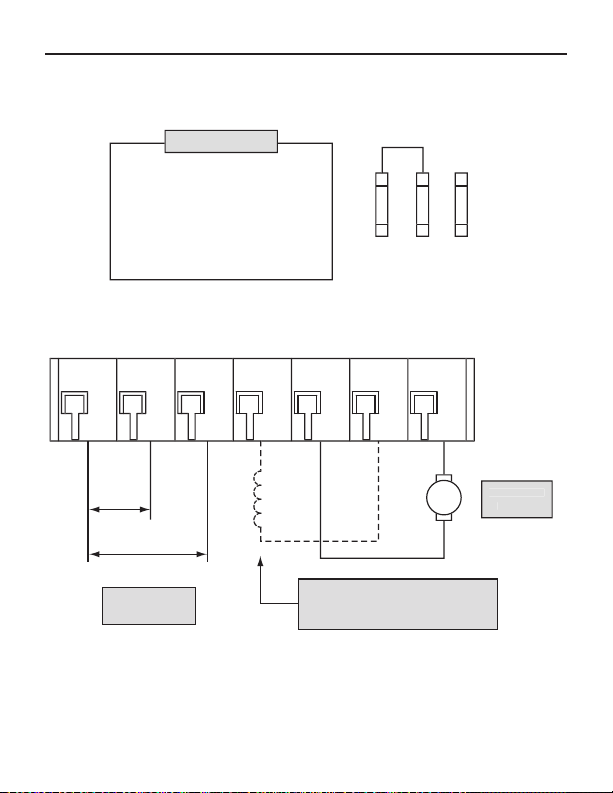
Figure 5. XL3300A Connections
PD and SPD IN are prewired fo
speed adjust potentiometer control
To control speed with a JOG trimme
otentiometer, connect SPD IN to JOG
Motor will not turn if there is n
connection to SPD IN
TB
11
2
VA
115
VAC
AC LINE VOLTAGE
(115 or 230 VAC)
P
P
MOT
FIELD OUTPUT
Shunt wound motors only.
See Field Output section for connections
ARMATUR
UTPU
Page 16
10
Installation
Field output
The field output is for shunt wound motors only. Do not make any
connections to the field output when using a permanent magnet
motor. Table 1 shows where to connect the field leads of a shunt
wound motor.
Use 18 AWG wire to connect the field output to a shunt wound
motor.
Line Voltage Approximate Field XL3300A Field
(VAC) Voltage (VDC) Connections
115 50 F+ and L1
115 100 F+ and F-
230 100 F+ and L1
230 200 F+ and F-
Table 1. Field Output Connections
Page 17
11Installation
Speed adjust potentiometer
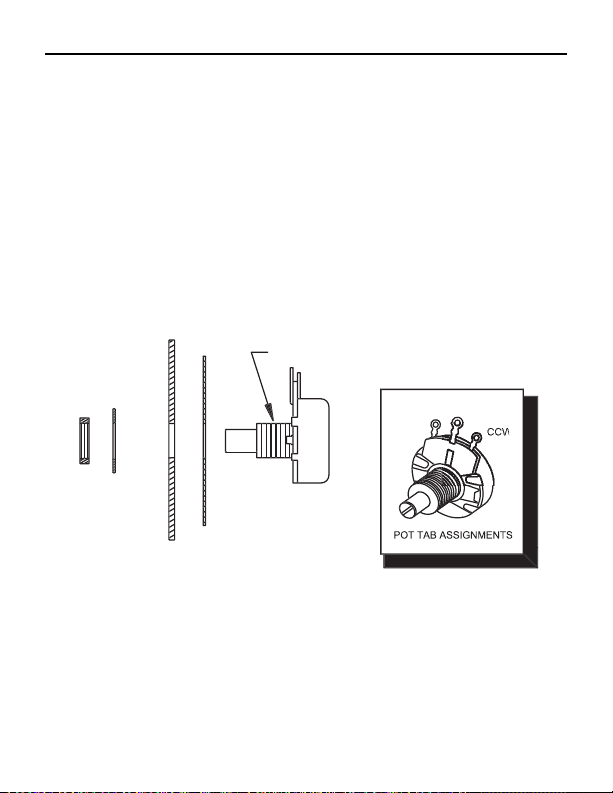
Install the circular insulating disk between the panel and the 10K
ohm speed adjust potentiometer. Mount the speed adjust
potentiometer through a 0.38 inches (10 mm) hole with the
hardware provided (Figure 6). Twist the speed adjust
potentiometer wire to avoid picking up unwanted electrical noise. If
potentiometer leads are longer than 18 inches (457 mm), use
shielded cable. Ground only one end of the shield.
JUST
S
E
Figure 6. Speed Adjust Potentiometer
UNT THROUGH A 0.38 IN. (10 MM) HOL
W
WA
TAR
HER
NSULATING DISK
PEED AD
POTENTIOMETER
Page 18
12 Installation
Fusing
The XL3300A has three 25A, fast-acting fuses installed (FU501 -
FU503). FU501 connects with the L1 terminal (the hot leg of the
AC line voltage). FU502 connects with the 230 terminal. FU503
connects with the A2 terminal to protect the motor from related
conditions not protected by the AC line fuses. If the horsepower
rating of the motor is less than the maximum horsepower rating of
the drive, replace the fuse with a lower rated one. Rate fuses at
150% times the maximum armature current.
Page 19
13
Voltage Follower
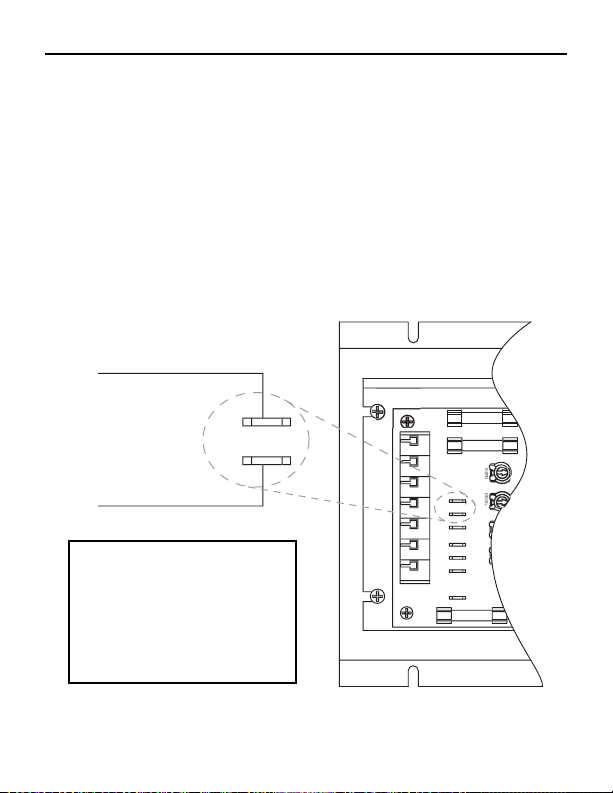
Instead of using a speed adjust potentiometer, the drive may be
wired to follow an analog input voltage that is isolated from earth
ground. Connect the signal input (+) to S2 and the signal common
(-) to S1 (Figure 7). Make no connection to S3. A potentiometer
can be used to scale the analog input voltage if needed. To
achieve greater linearity and control, use an interface device such
as a Minarik model PCM4 to scale the analog input voltage.
Installation
2
2
F-
OG
S
D
S
D
IN
1
F+
S2
S3
TB501
S1
115
230
1
CC
L
OG
S2
S1
Figure 7. Voltage Follower Connections
NOTE: The analog input voltage
range is 0 - 2.5 VDC for 0 - 130
VDC armature voltage range, and
0 - 5 VDC for 0 - 240 VDC
armature voltage range.
Signal Common
-
L
Signal Input
+
A
P
P
A
J
A
MI A
E
J
Page 20
14
Before applying power
Operation
• Verify that no conductive material is present on the printed circuit
board.
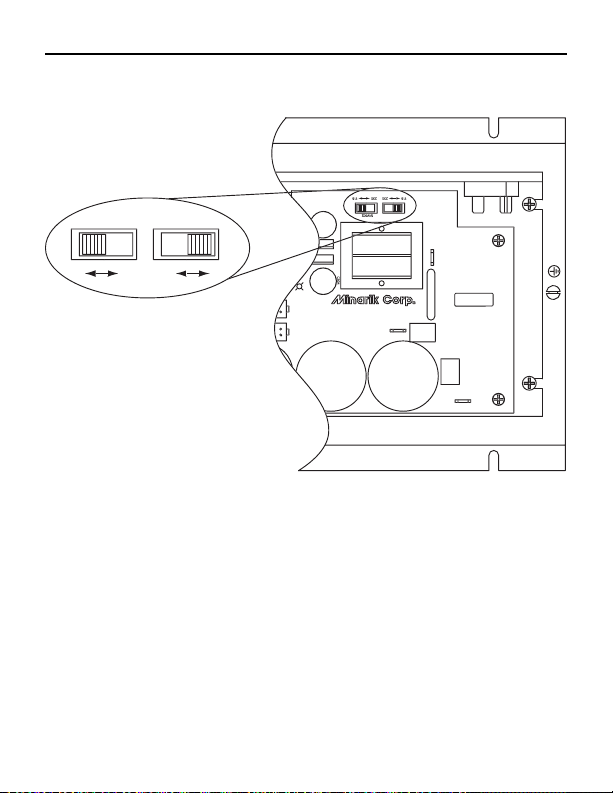
• Set both voltage selection switches (SW501 and SW502) to
either 115 or 230 to match the AC line voltage being used. See
Figure 8 (page 16).
Warning
Change voltage selection switch settings only when the drive
is disconnected from the AC line voltage. Make sure both
switches are set to their correct position. If the switches are
improperly set to a lower voltage position, the motor will not
run at full voltage. If the switches are improperly set to a
higher voltage position, the motor will overspeed, which may
cause motor damage.
Page 21
15Operation
01
01
6
C507
1
LIMIT
C
R
C
IC502
501
C
2
S
W501
S
03
S
BR-BR
C2
C1
C508
230 115
502W501
Figure 8. Voltage Selector Switches
W
50
I
501
UR
C50
T
A
A
A
+
+BU
TH5
R5
R5
-BU
Page 22
16
Operation
Startup
1. Turn the speed adjust potentiometer full counterclockwise
(CCW).
2. Apply AC line voltage.
3. Slowly advance the speed adjust potentiometer clockwise (CW).
The motor slowly accelerates as the potentiometer is turned
CW. Continue until the desired speed is reached.
4. Remove AC line voltage from the drive to coast the motor to a
stop.
If the motor or drive does not perform as described, disconnect the
AC line voltage immediately. Refer to the
Troubleshooting section
on page 40 for further assistance.
Diagnostic LEDs
XL3300A drives are equipped with the following diagnostic LEDs:
• The green POWER ON LED turns on when power is applied to
the drive and turns off when power is removed.
• The red CURR LIMIT LED turns on when the drive reaches
current limit and turns off when the drive is not in current limit
(normal operation).
Page 23
17Operation
Starting and Stopping Methods
Line starting and line stopping
Line starting and line stopping (applying and removing AC line
voltage) is recommended for infrequent starting and stopping of a
drive only. When AC line voltage is applied to the drive, the motor
accelerates to the speed set by the speed adjust potentiometer.
When AC line voltage is removed, the motor coasts to a stop.
Inhibit circuit
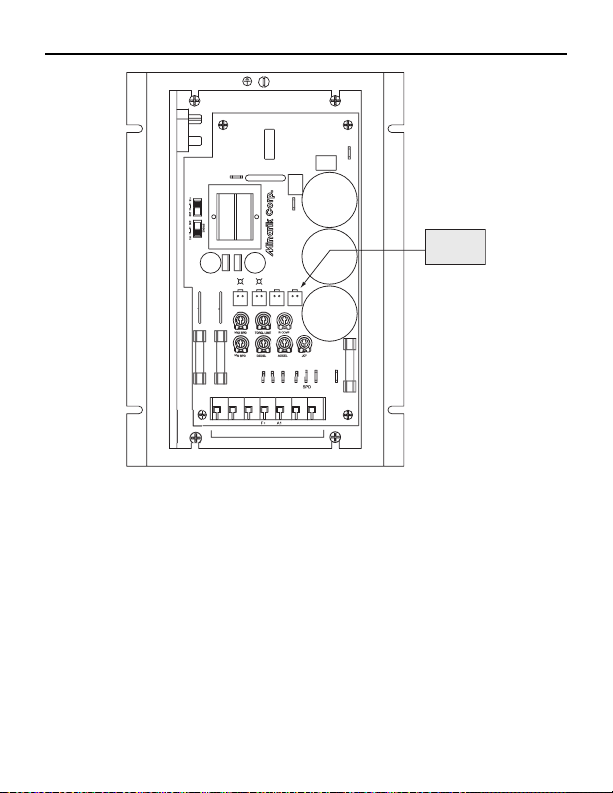
The XL3300A has an inhibit circuit that causes the motor to coast
to zero speed when the inhibit pins are shorted together.
Removing the connection between the inhibit pins allows the motor
to accelerate to the speed set by the speed adjust potentiometer
(see Figure 9, page 19).
Warning
The inhibit circuit is used for frequent starts and stops. It
must never be used as an emergency stop. It may not stop
a drive that is malfunctioning. Removing AC line power
(both L1 and L2) is the only acceptable method for
emergency stopping.
Page 24
18
Operation
Minarik Corporation offers two accessory plug harnesses for
connecting to the inhibit pins: part number 201-0024 [inhibit plug
with 18 in. (46 cm) leads]; and part number 201-0079 [inhibit plug
with 36 in. (91 cm) leads]. Twist these leads and separate them
from other power-carrying wires or sources of electrical noise. Use
shielded cable if the inhibit leads are longer than 18 in. (46 cm). If
shielded cable is used, ground only one end of the shield to earth
ground. Do not ground both ends of the shield.
501
501
JOG
SPD
C505
C506
C507
S2
S3
501
S1115230
1
PS3
S4
5
CURR
502
R
501
PS1
S2
C504
CURR
R
C501
ON
C502
501
C502
S
1
US
503
US
BR-
BR+
C1
Figure 9. Inhibit Pins
AC2A
+B
TH
T
W50
I
I
POWE
P
P
IL
IL
POWE
TB
L
R
-B
R
INHIBIT
PINS
+1
A2F
Page 25
19
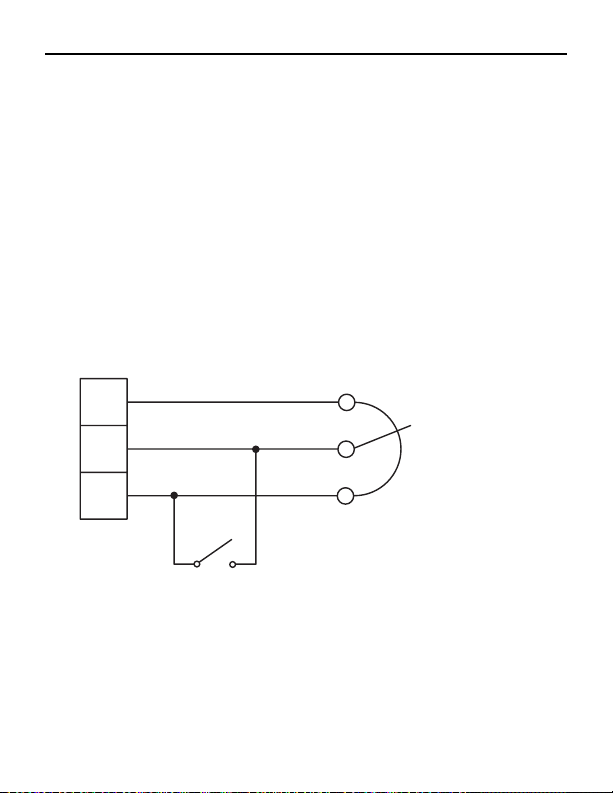
Decelerating to minimum speed
The circuit shown in Figure 10 may be used to decelerate a motor
to a minimum speed. Closing the switch between S1 and S2
decelerates the motor from set speed to a minimum speed
determined by the MIN SPD trimpot setting. If the MIN SPD
trimpot is set full CCW, the motor decelerates to zero speed when
the switch between S1 and S2 is closed. The DECEL trimpot
setting determines the rate at which the drive decelerates. By
opening the switch, the motor accelerates to set speed at a rate
determined by the ACCEL trimpot setting.
Figure 10. Run/Decelerate to Minimum Speed Switch
Operation
S3
S2
S1
RUN
DECEL TO
MIN SPEED
CW
10K OHM
SPEED ADJUST
POTENTIOMETER
Page 26
20
Operation
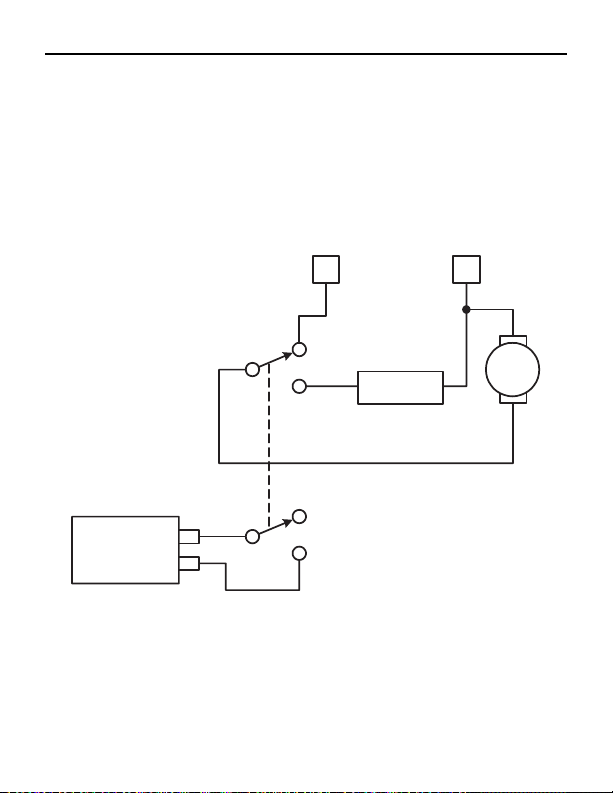
Dynamic braking
Dynamic braking may be used to rapidly stop a motor (Figure 11).
For the RUN/BRAKE switch, use a double-pole, double-throw
switch rated for at least the maximum DC armature voltage and
maximum braking current.
Figure 11. Run/Decelerate to Zero Speed Switch
A2A1
RUN
DYNAMIC BRAKE
BRAKE
RESISTOR
INHIBIT
MOTOR
Page 27
21
Size the dynamic brake resistor according to the motor current
rating (see Table 2). The dynamic brake resistance listed in the
table is the smallest recommended resistance allowed to prevent
possible demagnetization of the motor. The motor stops less
rapidly with higher brake resistor values.
Table 2. Recommended Dynamic Brake Resistor Sizes
Motor Armature Minimum Dynamic Minimum Dynamic
Current Rating Brake Resistor Brake Resistor
(ADC) Value (Ohms) Power (Watts)
5 - 10 20 20
10 - 17 40 50
Operation
Page 28
22
Each drive is factory calibrated to its maximum horsepower rating.
Readjust the calibration trimpot settings to accommodate lower
current rated motors.
All adjustments increase with CW rotation, and decrease with CCW
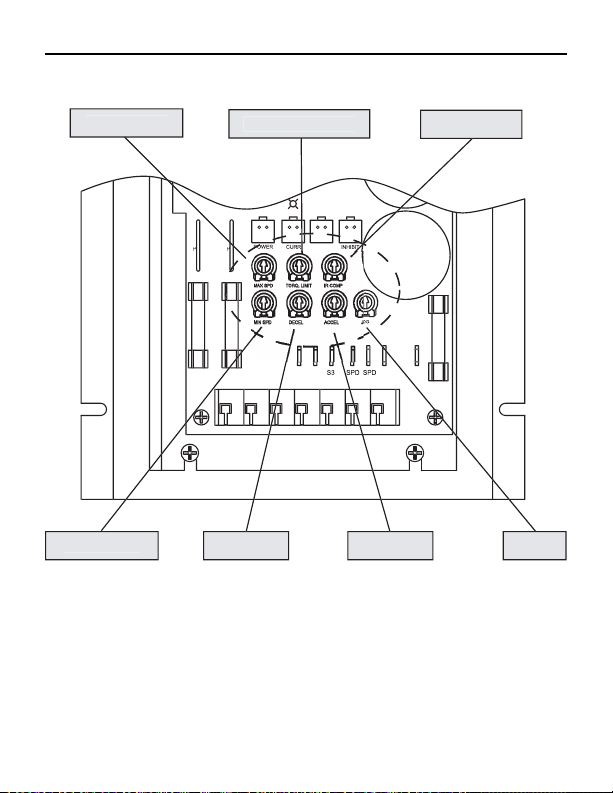
rotation. Use a non-metallic screwdriver for calibration. Each
trimpot is identified on the printed circuit board. See Figure 12
(page 24) for trimmpot locations.
Calibration
Warning
Dangerous voltages exist on the drive when it is powered.
When possible, disconnect the voltage input from the drive
before adjusting the trimpots. If the trimpots must be adjusted
with power applied, use insulated tools and the appropriate
personal protection equipment. BE ALERT. High voltages can
cause serious or fatal injury.
Page 29
23Calibration
Figure 12. Calibration Trimpot Layout
JOG
C505
S2
TB501
S1
30
S4
5
502IL501
D
D
T
P
LECEL
MAX SP
MIN SP
TORQ. LIMI
P
IL
2
+1
IR COM
A
ACCE
Page 30
Minimum Speed (MIN SPD)
The MIN SPD setting determines the motor speed when the speed
adjust potentiometer is turned full CCW. It is factory set for
minimum rated speed.
To calibrate, set the MIN SPD trimpot full CCW. Turn the speed
adjust potentiometer full CCW. Adjust the MIN SPD trimpot until the
desired minimum motor speed is reached.
Maximum Speed (MAX SPD)
The MAX SPD setting determines the motor speed when the speed
adjust potentiometer is turned full CW. It is factory set for maximum
rated speed.
To calibrate, set the MAX SPD trimpot full CCW. Turn the speed
adjust potentiometer full CW. Adjust the MAX SPD trimpot until the
desired maximum motor speed is reached.
24
Calibration
Page 31
25
Torque Limit (TORQ LIMIT)
The TORQ. LIMIT setting determines the maximum armature current
output of the drive. It is factory set at 120% of rated motor current.
Recalibrate the TORQ. LIMIT setting when using a lower horsepower
motor. Refer to Figure 13 (page 30) for approximate TORQ. LIMIT
settings, or recalibrate using the following procedure:
1. With the power disconnected from the control, connect a DC
ammeter (0 - 15 minimum scale) in series with the armature.
2. Set the TORQ. LIMIT trimpot to minimum (full CCW).
3. Set the speed adjust potentiometer to maximum speed
(full CW).
4. Carefully lock the motor armature. Be sure that the motor is firmly
mounted.
5. Apply line power. The motor should be stopped.
6. Slowly adjust the TORQ. LIMIT trimpot CW until the armature
current is 120% of motor rated armature current.
7. Turn the speed adjust potentiometer CCW until the motor stops.
8. Remove the line power.
9. Remove the stall from the motor.
10. Remove the ammeter in series with the motor armature if it is no
longer needed.
Warning
TORQ. LIMIT should be set to 120% of motor nameplate
current rating. Continuous operation beyond this rating may
damage the motor. If you intend to operate beyond the rating,
contact your Minarik representative for assistance.
Calibration
Page 32
26
Calibration
Acceleration (ACCEL)
The ACCEL setting determines the time the motor takes to ramp to
a higher speed. See Specifications on page 1 for approximate
acceleration times. ACCEL is factory set to its minimum value (full
CCW).
Use the following procedure to set the acceleration time:
1. Set the speed adjust potentiometer full CCW. The motor should
run at minimum speed (as set by the MIN SPD trimpot, page
25).
2. Turn the speed adjust potentiometer full CW and measure the
time it takes the motor to go from minimum to maximum speed.
3. If the time measured in step 2 is not the desired acceleration
time, turn the ACCEL trimpot CW for a slower acceleration time,
or CCW for a faster acceleration time. Repeat steps 1 through 3
until the acceleration time is correct.
Page 33
27
Deceleration (DECEL)
The DECEL setting determines the time the motor takes to ramp to
a lower speed. See Specifications on page 1 for approximate
deceleration times. DECEL is factory set for the fastest
deceleration time (full CCW).
Use the following procedure to set the deceleration time:
1. Set the speed adjust potentiometer full CW. The motor should
run at maximum speed (as set by MAX SPD trimpot, page 25).
2. Turn the speed adjust potentiometer full CCW and measure the
time it takes the motor to go from maximum to minimum speed.
3. If the time measured in step 2 is not the desired deceleration
time, turn the DECEL trimpot CW for a slower deceleration time,
or CCW for a faster deceleration time. Repeat steps 1 through
3 until the deceleration time is correct.
Calibration
Page 34
IR Compensation (IR COMP)
The IR COMP trimpot setting determines the degree to which
motor speed is held constant as the motor load changes. It is
factory set for optimum motor regulation.
Recalibrate the IR COMP setting when using a lower current rated
motor. Refer to Figure 13 (page 30) for approximate IR COMP
settings, or use the following procedure to recalibrate the IR
COMP:
1. Set the IR COMP trimpot to minimum (full CCW).
2. Rotate the speed adjust potentiometer until the motor runs at
midspeed without load (for example, 900 RPM for an 1800 RPM
motor). A hand held tachometer may be used to measure
motor speed.
3. Load the motor armature to its full load armature current rating.
The motor should slow down.
4. While keeping the load on the motor, rotate the IR COMP
trimpot until the motor runs at the speed measured in step 2. If
the motor oscillates (overcompensation), the IR COMP trimpot
may be set too high (CW). Turn the IR COMP trimpot CCW to
stabilize the motor.
5. Unload the motor.
28
Calibration
Page 35
29
JOG
The JOG setting determines the motor speed when the drive is set
to the JOG mode. To control the speed with the JOG trimpot:
1. Connect the SPD IN and JOG terminals.
2. Calibrate the JOG trimpot until the motor runs at the desired
JOG speed.
Figure 13. XL3300A TORQ. LIMIT and IR COMP Settings
Calibration
1/4 HP
90 VDC
1750 RPM
TORQ LIMIT IR COMP
TORQ LIMIT IR COMP
TORQ LIMIT IR COMP
2.5 AMPS
1/2 HP
90 VDC
1750 RPM
5 AMPS
1 HP
90 VDC
1750 RPM
10 AMPS
TORQ LIMIT IR COMP
TORQ LIMIT IR COMP
TORQ LIMIT IR COMP
1/2 HP
180 VDC
1750 RPM
2.5 AMPS
1 HP
180 VDC
1750 RPM
5 AMPS
2 HP
180 VDC
1750 RPM
9 AMPS
Page 36
30
Calibration
Calibration with low voltage DC motors
Using XL3300A with a low voltage DC motor requires using a lower
resistance speed adjust potentiometer, and recalibrating the MAX
SPD trimpot settings. See Figure 14 for MAX SPD trimpot settings.
NOTE: MAX SPD trimmer pot settings are approximate. Verify
maximum armature voltage with a voltmeter. Care should be taken
when using low voltage motors to ensure motor insulation rating is
above bus voltage of the drive.
Figure 14. XL3300A MAX SPD Settings for Low Voltage DC Motors
MAX SPEED TRIMPOT SETTING
MOTOR ARMATURE
VOLTAGE (VDC)
12
USING 2.5K OHM
SPEED ADJUST
POTENTIOMETER
(202-0056)
NOT
APPLICABLE
USING 1.5K OHM
SPEED ADJUST
POTENTIOMETER
(202-0001)
NOT
APPLICABLE
24
36
48
NOT
APPLICABLE
NOT
APPLICABLE
Page 37
31
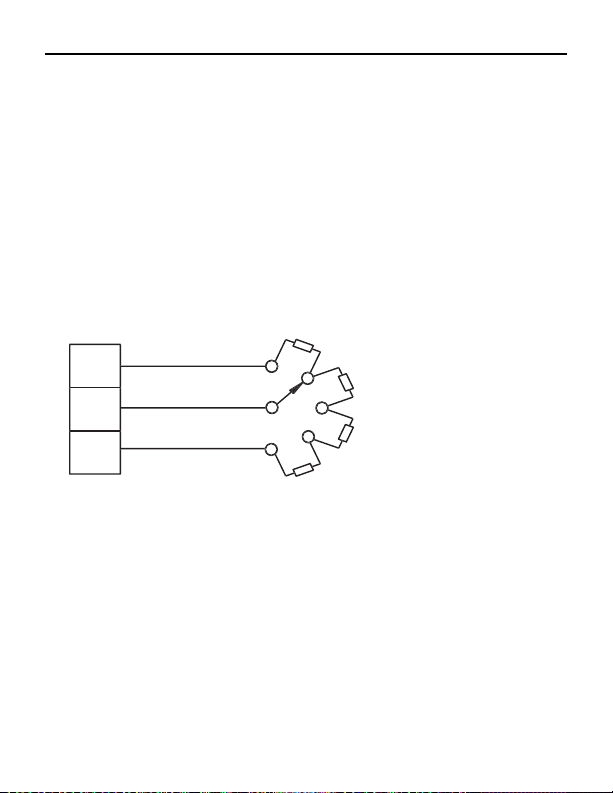
Multiple Fixed Speeds
Replace the speed adjust potentiometer with series resistors with a
total series resistance of 10K ohms (Figure 15). Add a single-pole,
multi-position switch with the correct number of positions for the
desired number of fixed speeds.
Figure 15. Multiple Fixed Speeds
Application Notes
S
CE
S
3
TAL SERIE
RESISTAN
1
R
K OHM
Page 38
32
Application Notes
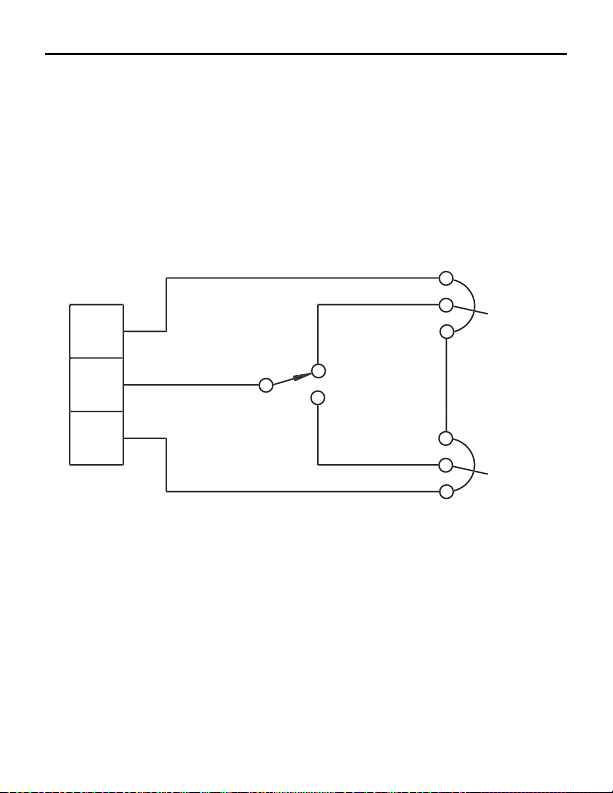
Adjustable Speeds using Potentiometers in Series
Replace the speed adjust potentiometer with a single-pole, multi-
position switch, and two or more potentiometers in series, with a
total series resistance of 10K ohms. Figure 16 shows a connection
for fixed high and low speed adjust potentiometers.
M
M
GH
D
D
Figure 16. Adjustable Fixed Speeds Using Potentiometers in Series
W
I
PEE
LOW
1
PEE
H
W
H
Page 39
33
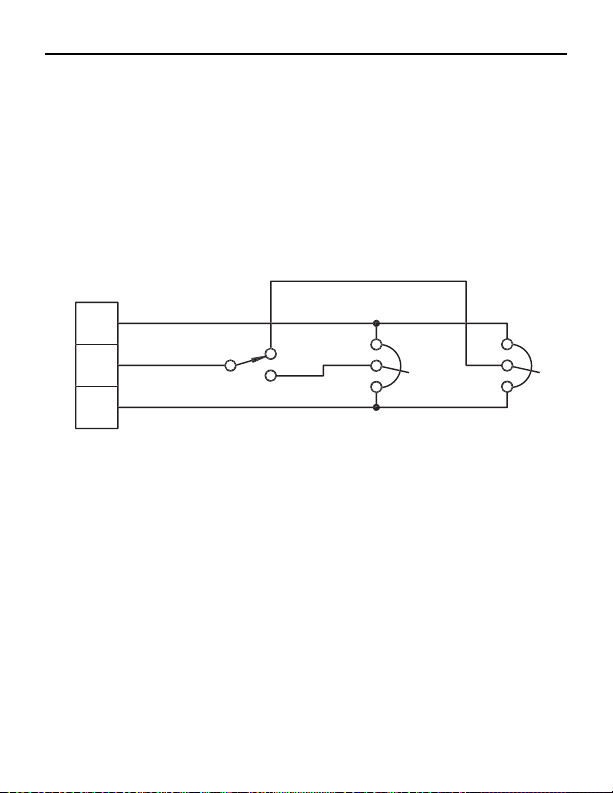
Independent Adjustable Speeds
Replace the speed adjust potentiometer with a single-pole, multi-
position switch, and two or more potentiometers in parallel, with a
total parallel resistance of 10K ohms. Figure 17 shows the
connection of two independent speed adjust potentiometers that
can be mounted at two separate operating stations.
2
20
M
20
M
Figure 17. Independent Adjustable Speeds
Application Notes
PEED
PEED 1
1
W
K
H
W
K
H
Page 40
34
Application Notes
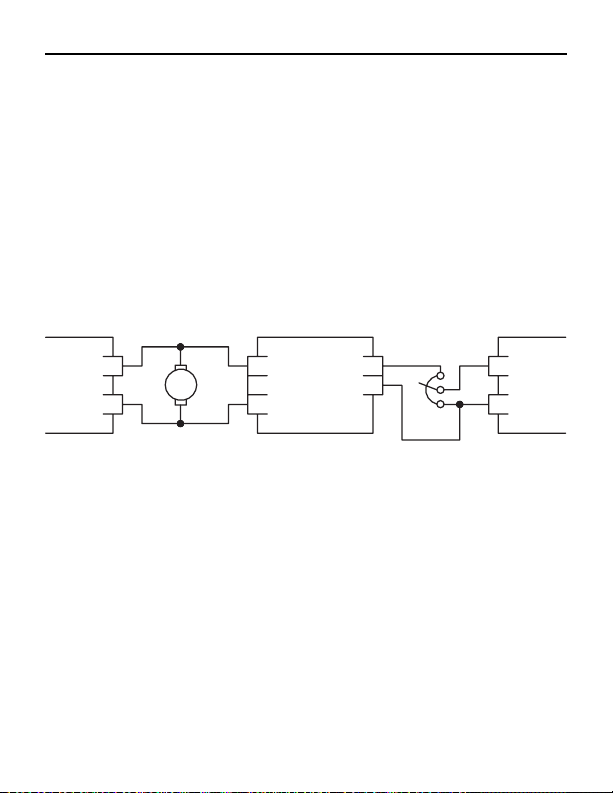
Leader-Follower Application
In this application, use a PCM4 to monitor the speed of the leader
motor (Figure 18). The PCM4 isolates the leader motor from the
follower drive, and outputs a voltage proportional to the leader
motor armature voltage. The follower drive uses this voltage
reference to set the speed of the follower motor. An optional ratio
potentiometer may be used to scale the PCM4 output voltage.
Figure 18. Independent Forward and Reverse Speeds
(+)
TB502
2
1(-)
10K Ohm
(optional)
9
Leader
Drive
A1
A2
MOTOR
8
7
(+)
(-)
TB501
PCM4
S2
Follower
Drive
S1
Page 41
35
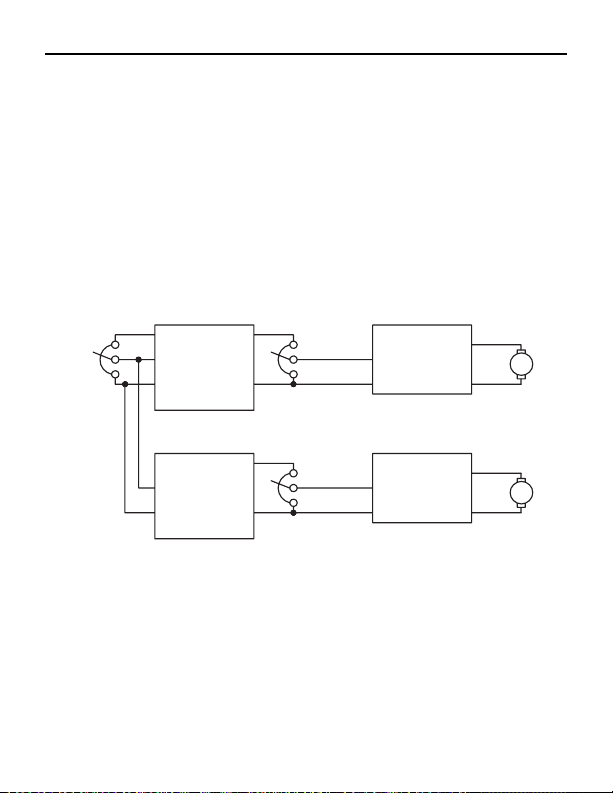
Single Speed Potentiometer Control of
Multiple Drives
Multiple drives can be controlled with a single speed adjust
potentiometer using a PCM4 at the input of each drive to provide
isolation (Figure 19). Optional ratio potentiometers can be used to
scale the PCM4 output voltage, allowing independent control of
each drive.
Figure 19. Single Speed Potentiometer Control of Multiple Drives
Application Notes
ratio pot A
2
PCM4
1
TB502TB501
PCM4
17
TB502TB501
10K Ohms
6
8
7
62
8
(optional)
10K Ohms
ratio pot B
(optional)
10K Ohms
A1
Drive
S2
A
Drive
A2
A1
B
A2
S1
S2
S1
Motor
Motor
A
B
Page 42
36
Application Notes
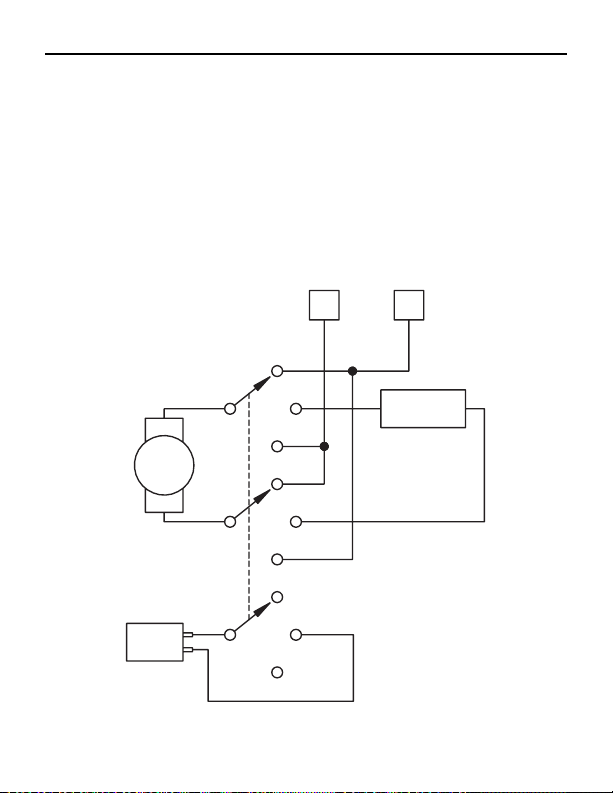
Reversing
A dynamic brake may be used when reversing the motor direction
(Figure 20). Use a three-pole, three-position switch rated for at
least the maximum DC armature voltage and maximum braking
current. Wait for the motor to stop completely before switching it to
either the forward or reverse direction. See page 22 for
recommended dynamic brake resistor sizes.
Figure 20. Independent Forward and Reverse Speeds
A1 A2
DYNAMIC
BRAKE
RESISTOR
MOTOR
INHIBIT
FWD
BRAKE
REV
Page 43
37
ake
l
code
on
l
C
C600
hibi
Reversing with a DLC600 Controller
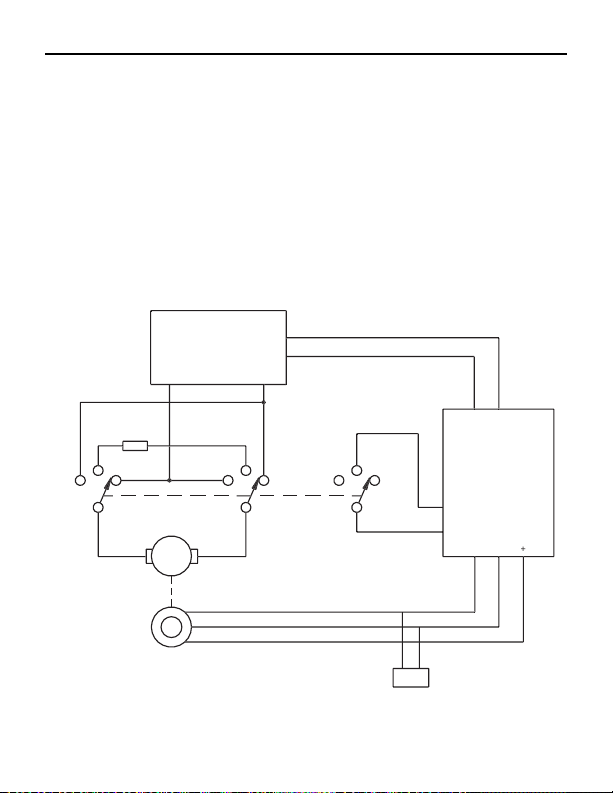
A DLC600 controller can be used in a reversing application. The
DLC600 must be inhibited while braking. Without the inhibit feature,
the DLC600 will continue to regulate. This will cause overshoot
when the DLC600 is switched back to the drive. Figure 21 shows
the connection of the reversing circuit to an XL3300A series drive
and a DLC600. NOTE: Only one DLC option (Optical Encoder or
Magnetic Pickup) may be used at a time.
Figure 21. Independent Forward and Reverse Speeds
Application Notes
1
namic
r
tor
tor
mm
ptica
n
r
igna
VD
agnetic
ckup
1
DL
n
t
Page 44
38
Warning
Dangerous voltages exist on the drive when it is powered.
When possible, disconnect the drive while troubleshooting.
High voltages can cause serious or fatal injury.
Troubleshooting
Before applying power
Check the following steps before proceeding:
1. Disconnect AC line voltage from the drive.
2. Check the drive closely for damaged components.
3. Check that no conductive or other foreign material has become
lodged on the printed circuit board.
4. Verify that every connection is correct and in good condition.
5. Verify that there are no short circuits or grounded connections.
6. Check that the voltage selection switch settings match the AC
line and output voltages.
7. Check that the drive’s rated armature and field outputs are
consistent with the motor ratings.
For additional assistance, contact your local Minarik distributor, or
the factory direct:
1-800-MINARIK (646-2745) or Fax: 1-800-394-6334
Page 45
39Troubleshooting
Line fuse blows.
Line fuse does not blow,
but the motor does not
run.
1. Line fuse is the
wrong size.
2. Motor cable or
armature is shorted
to ground.
1. Speed adjust
potentiometer or
reference voltage is
set to zero speed.
2. Speed adjust
potentiometer or
reference voltage is
not connected to
drive input properly;
connections are
open.
3. INHIBIT terminals are
jumpered.
4. S2 is shorted to S0.
1. Check that the line
fuse is correct for the
motor size.
2. Check motor cable
and armature for
shorts.
1. Increase the speed
adjust potentiometer
setting or reference
voltage.
2. Check connections to
input. Verify that
connections are not
open.
3. Remove jumper from
the INHIBIT
terminals.
4. Remove short.
Problem Possible
Causes
Suggested
Solutions
Page 46
40
Troubleshooting
Line fuse does not blow,
but the motor does not
run (cont.)
Motor runs too fast at
maximum speed setting
5. Drive is in current
limit.
6. Drive is not receiving
AC line voltage.
7. Motor is not
connected.
1. MIN SPD and MAX
SPD not calibrated.
2. Field output
connections are not
secure.
5. The red current limit
LED must be off. If
the red current limit
LED is on, verify that
the motor is not
jammed. It may be
necessary to
increase the TORQ.
LIMIT setting if it is
set to a value lower
than the current
rating of the motor.
6. Apply AC line
voltage to L1 and L2.
7. Connect motor to A1
and A2.
1. Calibrate MIN SPD
and MAX SPD .
Make sure settings
are not set too high.
2. Check that the field
output connections
are secure if you are
using a shunt wound
motor
Problem Possible
Causes
Suggested
Solutions
Page 47
41
Motor runs in opposite
direction.
Motor will not stop when
the speed adjust
potentiometer is full
counterclockwise
Motor pulsates or
surges under load.
1. Connections to motor
armature are
reversed.
1. MIN SPD is not
calibrated to zero.
1. IR COMP is set too
high.
2. Motor bouncing in
and out of current
limit.
1. Remove AC line
voltage and reverse
connections to the
motor armature.
1. Calibrate MIN SPD
trimpot to zero
speed.
1. Adjust the IR COMP
setting slightly CCW
until the motor speed
stabilizes.
2. Make sure motor is
not undersized for
load; adjust TORQ
LIMIT trimpot CW.
Problem Possible
Causes
Suggested
Solutions
Troubleshooting
Page 48
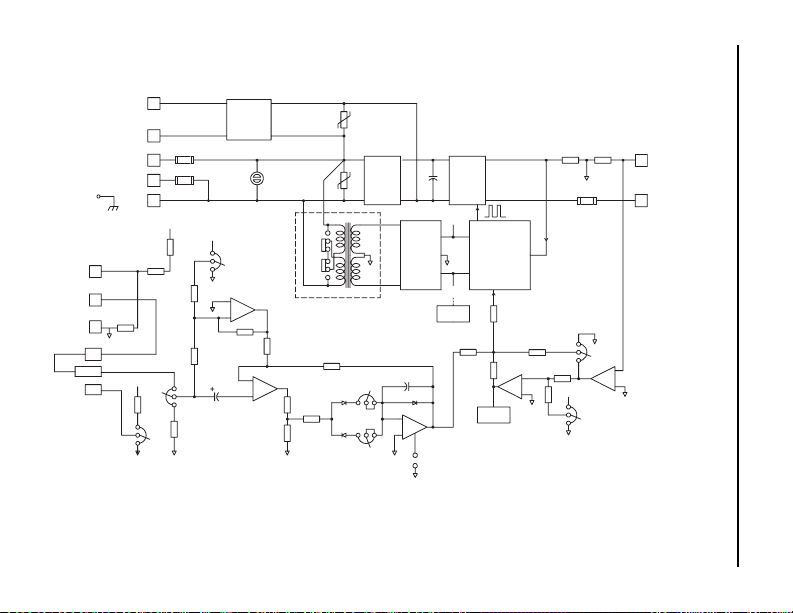
42
Block Diagrams
SPD IN
Figure 22. XL3300A Block Diagram
SPD terminal
is prewired to
SPD IN terminal.
SPD
JOG
S3
S2
S1
CHASSIS
GROUND
+
F1
-
F2
L1
230
115
+15
470
470
330K
470
51K
+15
50K
MAX
12K
SPEED
JOG
12K
5K
FIELD
SUPPLY
PS1 PS2
PS3
+15
5K
MIN
SPEED
56K
0.1
10K
POWER
LIGHT
PS4
CONTROL TRANSFORMER
10K
2.2K
+
+
CONTROL
LOGIC
POWER
6.8
+
INHIBIT
-
+15
-15
POWER
LED
OUTPUT
POWER
STAGE
PWM
GENERATOR
CURR LIMIT
CURRENT
LIMIT LED
PEAK CURRENT
DETECTOR
-15
INPUT
RECTIFIER
115-23 0 230-115
20K
500K
47K
500K
A1
-
A2
IR COMP
50K
50K
Page 49
43
Replacement parts are available from Minarik Corporation and its
distributors for this drive series.
Replacement Parts
Table 3. Replacement Parts
Model No. Symbol Description Minarik P/N
XL3300A BR601 35A, 600V Bridge 073-0008
C505-507 680 MF, 400 VDC Capacitor 011-0080
D501 16A, 600V Diode 071-0044
Q501,502 Power Mosfet 070-0066
R501 0.01 ohm, 5W Resistor 032-0129
T501 3FD-436 Transformer 230-0072
TH501 30A, 1 ohm Thermistor 033-0009
FU501-503 20A Slow Acting Fuse 050-0063
10K ohm Potentiometer Kit 202-0003
Line Fuse Kit (1 - 8A) 050-0068
Line Fuse Kit (3 - 10A) 050-0070
Line Fuse Kit (5 - 15A) 050-0072
1/2A Pico Fuse 050-0064
Page 50
44
Minarik Corporation hereby certifies that its MMRG series drives
has been approved to bear the “CE” mark provided the conditions
of approval have been met by the end user.
The MMRG series has been tested to the following test specifications:
EN55011:1993 (emissions), and
EN50082-1:1992 (immunity)
Compliance allows Minarik’s XL series drives to bear the CE mark.
The end user, as described herein, falls into one of two categories:
1. The Consumer will deploy a stand-alone unit as an
integral, yet external, portion of the machine being
operated.
2. The Original Equipment Manufacturer (OEM) will
implement the product as a component of the machine
being manufactured.
Certificate of Compliance
Page 51
AC Line Filters
In addition to EMI/RFI safeguards inherent in the XL series design,
external filtering is required.
Minarik requires the AC line filters listed in Table 4. Use model
CE15XL with drives rated for 15A AC or below.
Table 4. AC Line Filters
Minarik
Model Number CE04XL CE10XL CE15XL
Rated Current 4A 10A 15A
Inductance 17.5 mH 14.3 mH 10.0 mH
Capacitance
Line to Line 0.82 mF 0.82 mF 0.82 mF
Line to Ground 0.0056 mF 0.0056 mF 0.0056 mF
Discharge Resistor 330 Kohms 330 Kohms 330 Kohms
Wire the AC line filter within 0.25 meters of the drive. The ground
connection from the filter must be wired to solid earth
ground (resistance less than 500 ohms); not machine
ground. This is very important!
If the end-user is using a CE-approved motor, the
correct filter from Table 4 is all that is necessary to
meet the EMC directirves listed herein.
45CE Compliance
Page 52
46
NOTES
Page 53
NOTES
47
Page 54
NOTES
48
Page 55
Unconditional Warranty
A. Warranty
Minarik Corporation (referred to as "the Corporation") warrants that its products will be
free from defects in workmanship and material for twelve (12) months or 3,000 hours,
whichever comes first, from date of manufacture thereof. Within this warranty period,
the Corporation will repair or replace, at its sole discretion, such products that are
returned to Minarik Corporation, 901 East Thompson Avenue, Glendale, CA 912012011 USA.
This warranty applies only to standard catalog products, and does not apply to
specials. Any returns for special controls will be evaluated on a case-by-case basis.
The Corporation is not responsible for removal, installation, or any other incidental
expenses incurred in shipping the product to and from the repair point.
B. Disclaimer
The provisions of Paragraph A are the Corporation's sole obligation and exclude all
other warranties of merchantability for use, express or implied. The Corporation further
disclaims any responsibility whatsoever to the customer or to any other person for
injury to the person or damage or loss of property of value caused by any product that
has been subject to misuse, negligence, or accident, or misapplied or modified by
unauthorized persons or improperly installed.
C. Limitations of Liability
In the event of any claim for breach of any of the Corporation's obligations, whether
express or implied, and particularly of any other claim or breech of warranty contained
in Paragraph A, or of any other warranties, express or implied, or claim of liability that
might, despite Paragraph B, be decided against the Corporation by lawful authority, the
Corporation shall under no circumstances be liable for any consequential damages,
losses, or expense arising in connection with the use of, or inability to use, the
Corporation's product for any purpose whatsoever.
An adjustment made under warranty does not void the warranty, nor does it imply an
extension of the original 12-month warranty period. Products serviced and/or parts
replaced on a no-charge basis during the warranty period carry the unexpired portion
of the original warranty only.
If for any reason any of the foregoing provisions shall be ineffective, the Corporation's
liability for damages arising out of its manufacture or sale of equipment, or use thereof,
whether such liability is based on warranty, contract, negligence, strict liability in tort, or
otherwise, shall not in any event exceed the full purchase price of such equipment.
Any action against the Corporation based upon any liability or obligation arising
hereunder or under any law applicable to the sale of equipment or the use thereof,
must be commenced within one year after the cause of such action arises.
Page 56
901 E Thompson Avenue
Glendale, CA 91201-2011
Tel.: 1-800-MINARIK (646-2745)
Fax: 1-800-394-6334
www.minarikcorp.com
Document Number 250-0217, Rev. 2
Printed in the U.S.A – October 2002
 Loading...