

Page 1
User Guide
Part Number: 0451-0024
Issue Number: 2
COMMANDERGGpp
model sizes 1 to 4
0.75kW to 110kW
(1HP to 150HP)
COMMANDERGGpp LVLV
model sizes 1 to 3
0.37kW to 22kW
(0.5HP to 30HP)
General Purpose Variable Speed Drive
for induction motors
Page 2
General information
The manufacturer accepts no liability for any
consequences resulting from inappropriate ,
negligent or incorrect installation or adjustment of
the optional operating parameters of the equipment
or from mismatching the variable speed drive
(Drive) with the motor.
The contents of this User Guide are believed to be
correct at the time of printing. In the interests of a
commitment to a policy of continuous development
and improvement, the manufacturer reserves the
right to change the specification of the product or
its performance, or the contents of the User Guide,
without notice.
All rights reserved. No parts of this User Guide may
be reproduced or transmitted in any form or by any
means, electrical or mechanical including
photocopying, recording or by any informationstorage or retrieval system, without permission in
writing from the publisher.
Important...
Drive software version
This product is supplied with the latest version of
user-interface and machine-control software. If this
product is to be used with other Control Techniques
variable speed drives in an existing system, there
may be some differences between their software
and the software in this product. These differences
will cause a difference in functions. This may also
apply to variable speed drives returned from a
Control Techniques Service Centre.
If there is any doubt, contact a Control Techniques
Drive Centre.
Copyright © March 2000 Control Techniques Drives Ltd
Author: RFD
Issue Code: gpxu2
Issue Date: March 2000
S/W Version: V03.XX.07 onward
Page 3
Contents
Chapter
1 Introduction 1-1
1.1 How this User Guide can help you 1-1
1.2 Model sizes 1-1
1.3 Configuration layers 1-2
1.4 Default configurations 1-2
1.5 Operating mode 1-2
1.6 User-interface modes 1-2
1.7 Macro configurations 1-3
1.8 Plug-in option modules 1-4
1.9 Serial communications 1-4
2 Getting Started 2-1
2.1 How to use this chapter 2-1
2.2 Making signal and power connections 2-1
2.3 Introduction to the display and keypad 2-6
Display and keypad 2-6
Resetting the Drive 2-7
2.4 Working with software parameters 2-7
Parameters 2-7
Types of parameter 2-7
Adjusting parameter values 2-7
Making new values effective, and saving
them 2-7
Parameter 0.00 2-8
2.8 Setting up operating limits 2-15
Minimum and maximum frequencies 2-15
Acceleration rate 2-15
Deceleration rate 2-15
Braking resistor 2-15
Torque producing current limit 2-16
Voltage-control modes 2-16
Boost voltage 2-17
Voltage/frequency characteristic 2-17
3 Setting Up the Drive
(Macro Configurations) 3-1
3.1 How to use this chapter 3-1
3.2 Enabling a different macro configuration3-1
3.3 Macro 0
(default configuration)
3.4 Macro 1
3.5 Macro 2
3.6 Macro 3
3.7 Macro 4
3.8 Macro 5
3.9 Macro 6
3.10 Macro 7
General purpose
Easy mode
Motorized potentiometer
Preset frequencies
Torque control
PID (set-point control)
Axis-limit control
Brake control
3-2
3-9
3-15
3-21
3-27
3-33
3-38
3-45
2.5 How macro configurations change the
arrangement of the Menu 0 parameters 2-8
2.6 Initial setting up 2-9
Restoring the Drive to a default
configuration 2-9
Enabling Macro 1 2-10
Configuring the Drive for the motor 2-10
Autotune 2-12
Changing the user interface mode 2-12
2.7 Operating instructions 2-13
Terminal mode 2-13
Keypad mode 2-14
Trip and enable 2-14
Commander GP User Guide
Issue code: gpxu2
d2
i
Page 4
Appendix
A Programming Instructions A-1
A.1 Electrical connections A-1
A.2 Preparation A-1
A.3 Status mode A-2
A.4 Displaying the parameter
number in Status mode A-2
A.5 Entering Parameter mode
and returning to Status mode A-2
A.6 Selecting a parameter to access A-3
A.7 Changing the value of a parameter A-4
A.8 Saving new parameter values A-6
A.9 Flashing and non-flashing digits A-6
A.10 Negative values A-6
A.11 Changing the setting
of a bit parameter A-6
A.12 Selecting a different option A-7
A.13 Restoring the Drive to a default
configuration A-7
A.14 Summary of key operation A-7
B Security B-1
B.1 User-defined Security B-1
B.2 Setting-up User Security B-1
B.3 Unlocking User Security B-1
B.4 Locking User Security B-1
B.5 Summary B-1
C Signal Connections C-1
D Menu 0 Parameters D-1
D.1 Introduction D-1
D.2 Fixed-function parameters common
to all macro configurations D-2
D.3 Parameters specific to the macro
configurations D-8
E Diagnostics E-1
E.1 Status indications E-1
E.2 Alarm indications E-1
E.3 Trip codes E-2
ii
Commander GP User Guide
Issue code: gpxu2
d2
Page 5
1 Introduction
1.2 Model sizes
This User Guide refers to the models listed below.
1.1 How this User Guide
can help you
If this is your first encounter with a
Commander Gp Drive, read this User Guide
before referring to the accompanying
Installation Guide.
This User Guide is arranged on a step-by-step basis
to lead you through the following:
• Learning how to operate the Commander
Gp (Drive)
• When to refer to the Installation Guide
• Setting up the Commander Gp for basic
applications
Advanced programming of the
Commander Gp
For advanced programming of the Commander Gp,
refer to the Commander Gp Advanced User Guide. This
contains descriptions of all the advanced
parameters, as well as additional information, and
can be obtained from the Drive Centres and
distributors listed at the end of this User Guide.
The advanced parameters in software version
V03.01.07 onward can be accessed by use of the
UD71 Basic serial communications large option module
(see Serial communications later in this chapter).
Model size Model code Nominal
rating for
standard AC
motors
kW
at 380VHPat 460V
GPD 1401 0.75 1.0
GPD 1402 1.1 1.5
GPD 1403 1.5 2.0
GPD 1404 2.2 3.0
GPD 1405 4.0 5.0
GPD 2401 5.5 7.5
GPD 2402 7.5 10
GPD 2403 11.0 15
GPD 3401 15.0 25
GPD 3402 18.5 30
GPD 3403 22.0 30
GPD 3404 30.0 40
GPD 3405 37.0 50
GPD 4401 45.0 75
GPD 4402 55.0 100
GPD 4403 75.0 125
GPD 4404 90.0 150
GPD 4405 110.0 150
Variable speed drives may be
hazardous if misused. Carefully
follow the instructions in this
Warning
User Guide and the Installation
Guide.
Commander GP User Guide
Issue code: gpxu2
Model size Model code Nominal rating
for standard
AC motors
KW
at 380VHPat 460V
GPD 1201 0.37 0.5
GPD 1202 0.55 0.75
GPD 1203 0.75 1.0
GPD 1204 1.1 1.5
GPD 1205 2.2 3.0
GPD 2201 3.0 4.0
GPD 2202 4.0 5.0
GPD 2203 5.5 7.5
GPD 3201 7.5 10
GPD 3202 11 15
GPD 3203 15 20
GPD 3204 22 30
Introduction 1-1
Page 6
1.3 Configuration layers
1.5 Operating mode
The Drive has three layers of configuration, starting
from the base layer (1) as follows:
1. Default configuration
2. User-interface mode
3. Macro configuration
Each of the upper layers (2, 3) is superimposed on its
preceeding layer.
1.4 Default configurations
The Drive has a separate default configuration for the
AC supply conditions in Europe or in the USA. These
two default configurations are distinguished as
follows:
European
USA
The Drive is despatched from the factory in the
appropriate default configuration for the continent
in which it is to be sold. The default configuration
is Macro 0 (described in Macro configurations later in
this chapter).
The default configuration also defines the following
functions:
Europe
• Ability to select positive-logic for the digital
• Ability to adjust the current-loop PI gains
USA
• Ability to select digital control by two or
• Frequency demand indication
(These functions apply to Macro 0 only.)
Key used in this User Guide
AC supply voltage at 50Hz
AC supply voltage at 60Hz
control inputs
three wires
For use with standard AC induction motors.
The Drive applies power to the motor at frequencies
which are controlled by the user. The motor speed
is a result of the output frequency of the Drive and
slip due to the mechanical load.
The Drive can power a number of motors connected
in parallel (each motor must be protected against
overload; this is described in the Installation Guide).
The Drive can improve the performance of the
motor by applying the following:
• Slip compensation
• Fixed boost or Open-loop Vector operation
Fixed boost applies a fixed voltage boost at low
frequencies.
Open-loop Vector operation maintains almost
constant flux by dynamically adjusting the
motor voltage according to the load on the
motor.
1.6 User-interface modes
The motor can be started and stopped, the
direction of rotation reversed and the speed
changed by operation of the Drive in either of the
following user-interface modes:
Terminal mode
Applying signals from electrical contacts, a
system controller or PLC to digital and analog
inputs on the Drive.
For the USA default configuration, the Drive can
be configured for digital control by momentary
contacts.
Keypad mode
Manual operation of the keypad on the front
panel of the Drive. Minimal signal connections
are made to the Drive.
The following key denotes the default
configuration:
EUR> 50Hz AC supply (Europe)
USA> 60Hz
When no key is stated, the information applies to
both default configurations.
AC supply (USA)
1-2 Introduction
Commander GP User Guide
Issue code: gpxu2
Page 7
1.7 Macro configurations
The Drive can be used to control the motor speed in
various ways for different types of application. To
reduce the number of adjustments to the Drive for
each type of application, eight macro configurations
(0 to 7) are available.
Macro 3
Preset frequencies
Four preset frequencies that are selected by external
contacts.
The macro configuration can be used in Terminal
mode only.
Each macro configuration requires specific signal
connections to be made to the Drive.
The macro configurations are as follows:
Macro 0
General purpose (default configuration)
Analog frequency control for general-purpose
applications.
The output frequency of the Drive is controlled by a
frequency reference. The motor speed will follow the
frequency reference so long as the maximum
permissible output current of the Drive is not
exceeded. These principles also apply to all other
macro configurations except Macro 4.
The macro configuration can be used in either
Keypad or Terminal mode.
The frequency can be controlled in either of the
following ways...
• Terminal mode: An analog frequency
reference signal applied to the Drive
• Keypad mode: By a user pressing keys on
the front panel of the Drive
Macro 1
Easy mode
Frequency control for basic applications. This is
similar to Macro 0, except, for simplicity, fewer
adjustments are required.
The macro configuration can be used in either
Keypad or Terminal mode.
The principles of controlling motor speed are the
same as for Macro 0.
The principles of controlling motor speed are the
same as for Macro 0.
Macro 4
Torque control
The motor torque is defined by a torque demand.
The motor speed will vary continuously as a result
of the difference between the load torque and the
torque demand up to a maximum speed which is
defined by a speed over-ride level.
The torque demand is supplied by an analog torque
reference signal that is applied to the Drive.
The macro configuration can be used in Terminal
mode only.
Macro 5
PID control
The Drive is operated with a frequency reference
and an analog feedback device in order to
dynamically maintain the speed to a user-defined
set-point under PID control.
The macro configuration can be used in Terminal
mode only.
The principles of controlling motor speed are the
same as for Macro 0.
Macro 6
Axis-limit control
Axis-limit control is used for applications which
require the process to be automatically stopped
when a position limit has been reached. A bipolar or
unipolar frequency reference can be used.
The macro configuration can be used in Terminal
mode only.
Macro 2
Motorized potentiometer
The frequency is controlled incrementally by
operation of up and down contacts.
The macro configuration can be used in Terminal
mode only.
The principles of controlling motor speed are the
same as for Macro 0.
Commander GP User Guide
Issue code: gpxu2
The principles of controlling motor speed are the
same as for Macro 0.
Macro 7
Brake control
Frequency control with brake control for crane or
hoist applications.
The macro configuration can be used in Terminal
mode or Keypad mode.
The principles of controlling motor speed are the
same as for Macro 0.
Introduction 1-3
Page 8
1.8 Plug-in option modules
Operation of the Drive can be extended by the use
of plug-in option modules. The following modules
are available from the supplier of the Drive; an
appropriate User Guide is included with each
module:
Small option modules
UD50 Additional I/O
UD55 Cloning (parameter copying)
Large option modules
UD71 RS232/RS485 serial
communications
1.9 Serial communications
The Drive can be configured and fully controlled
from a system controller or PLC operating on a
RS232 or a 4-wire RS485 serial communications link.
A Basic serial communications large option module
must be fitted in the Drive. More information can
be obtained from a Drive Centre or distributor
listed at the end of this User Guide.
Serial communications can be used in conjunction
with Terminal mode or Keypad mode.
1-4 Introduction
Commander GP User Guide
Issue code: gpxu2
Page 9
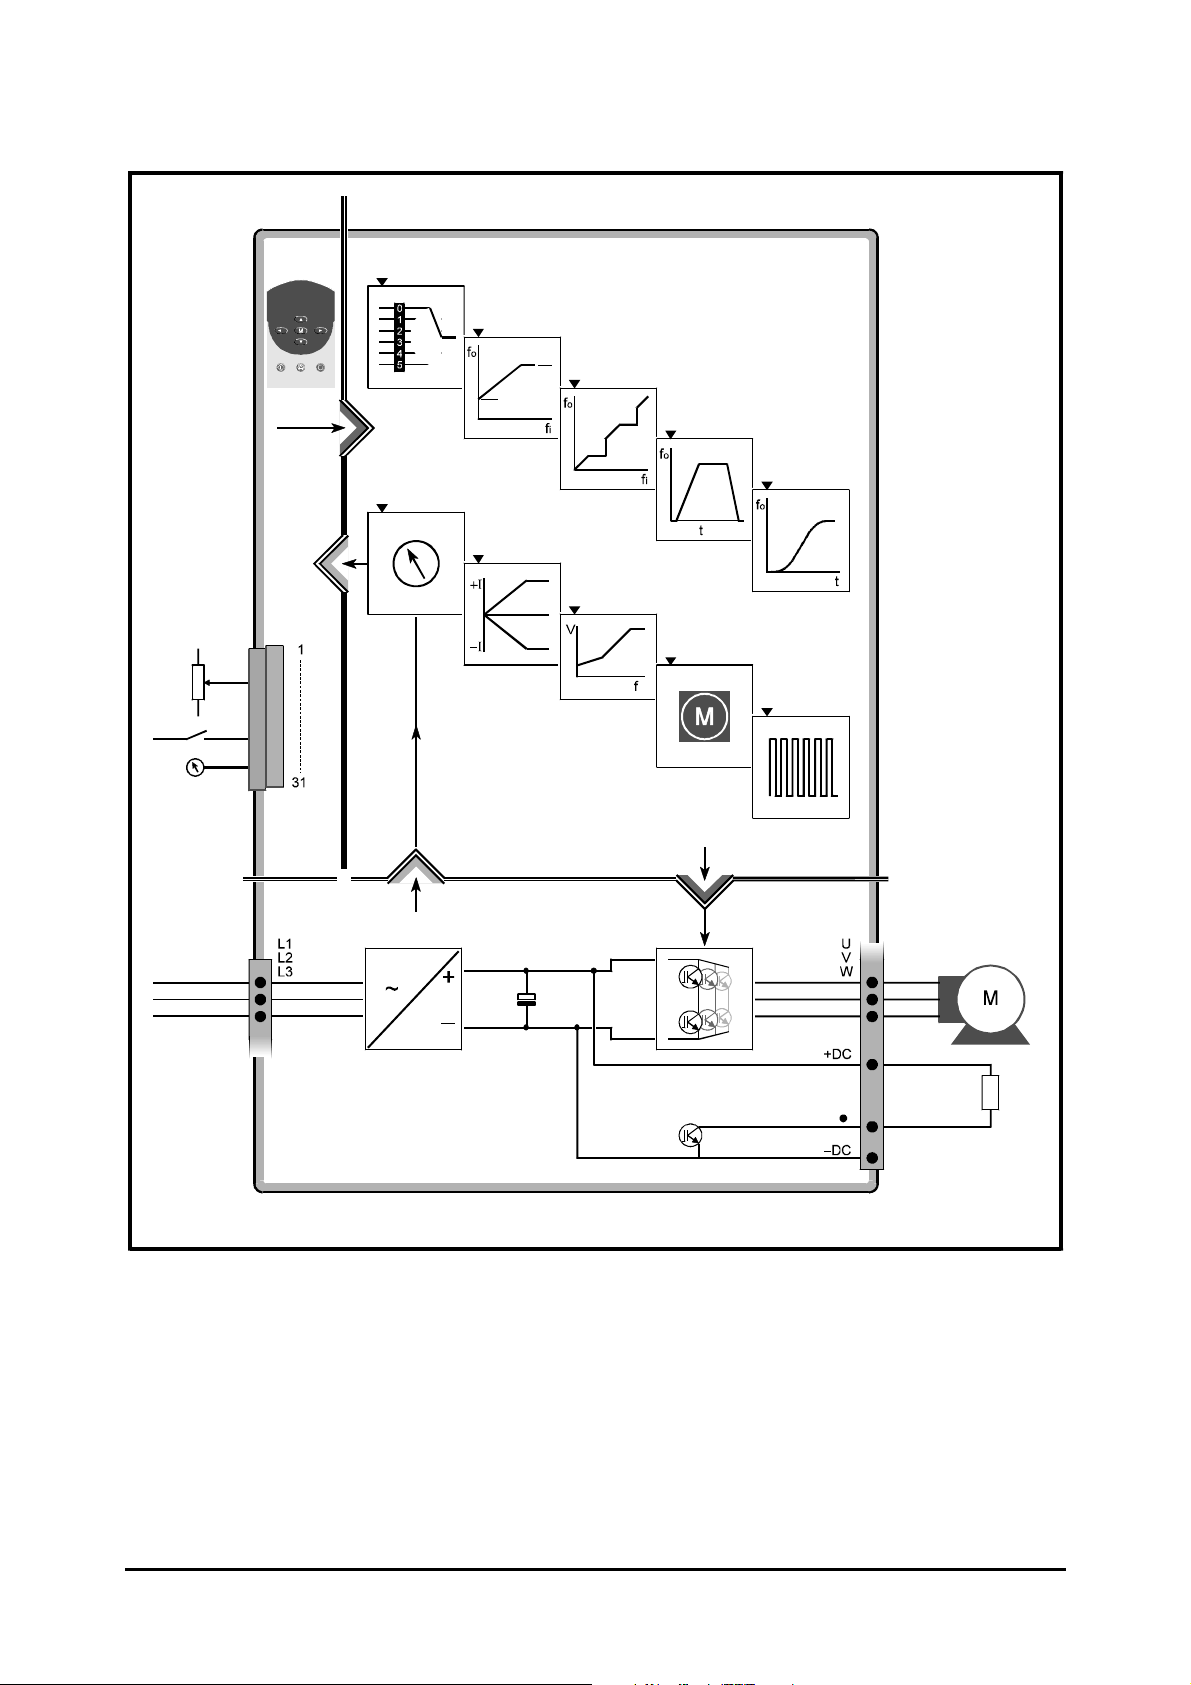
User interface
Display and
keypad
External
control and
monitoring
(analog and
digital)
User
control
Frequency reference
selection
Minimum and maximum
frequency limits
Monitoring
Current limit
Stop mode
Spinning motor sync.
Functions of the software
(controlled by the macro configurations)
Skip frequencies
Acceleration and
deceleration ramps
Voltage control
Motor parameters
S-ramp
PWM switching
frequency
Drive
Control
Monitoring
AC supply
DC bus
Power circuits
Figure 1–1 Block diagram of the Drive showing the main functions of the software,
and power connections (signal connections vary according to the
macro configuration)
Optional braking
resistor
Commander GP User Guide
Issue code: gpxu2
Introduction 1-5
Page 10
1-6 Introduction
Commander GP User Guide
Issue code: gpxu2
Page 11
2 Getting Started
2.2 Making signal and power
connections
2.1 How to use this chapter
It is recommended that you follow the instructions
in this chapter in the order that they appear. You
will be led through the initial stages of setting up
the Drive (in Macro 1 Easy mode) as well as being able
to familiarize yourself with operating the Drive.
The Drive must be operated
only by personnel having the
Warning
Warning
Warning
Warning
necessary training or
experience.
If this is the first time the
Drive has been operated,
ensure that no damage or
safety hazard could arise from
the motor starting
unexpectedly.
The motor must be fixed down
and the shaft guarded against
inadvertent contact.
Do not change parameter
values without careful
consideration; wrong values
may cause damage or a safety
hazard.
Stored charge
Warning
The Drive contains capacitors
that remain charged to a
potentially lethal voltage after
AC supply has been
the
disconnected. If the Drive has
been energized, the
must be isolated at least
ten minutes before work may
continue.
AC supply
Isolation
Warning
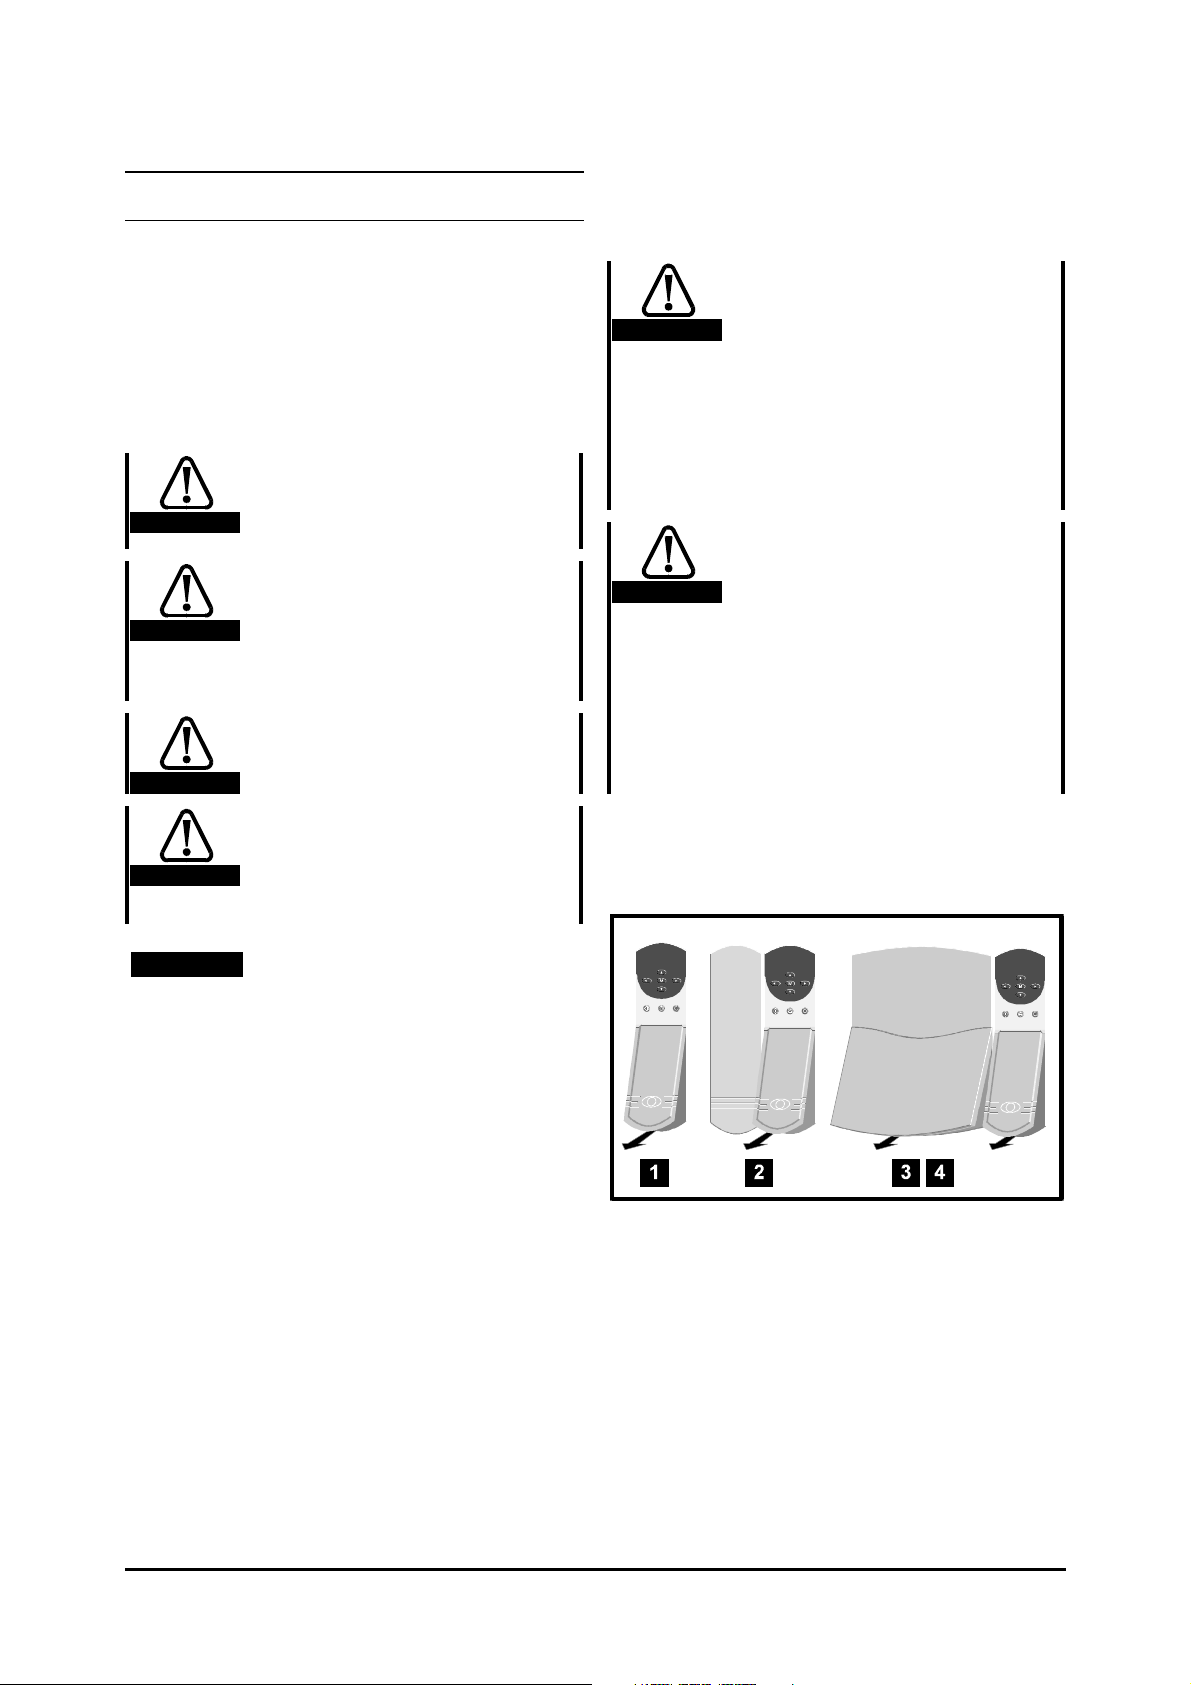
For instructions on removing the terminal covers,
see Mounting the Drive and RFI filter in Chapter 2
Installing the Drive in the Installation Guide.
The control circuits and
terminals are isolated from the
power circuits only by basic
insulation to IEC664–1. The
installer must ensure that all
external control circuits are
separated from human contact
by at least one layer of
insulation rated for use at the
AC supply voltage.
Notes
Keep a note of changes
When changing the values of parameters,
make a note of the new values in case they
need to be entered again.
Saving the changes
For new parameter-values to apply after
AC supply to the Drive is interrupted,
the
new values must be saved. This is described
in Saving new parameter-values in Appendix A
Programming Instructions.
Commander GP User Guide
Issue code: gpxu2
Figure 2–1 Removing the terminal covers for
access to the connectors
Getting Started 2-1
Page 12
111
21 31
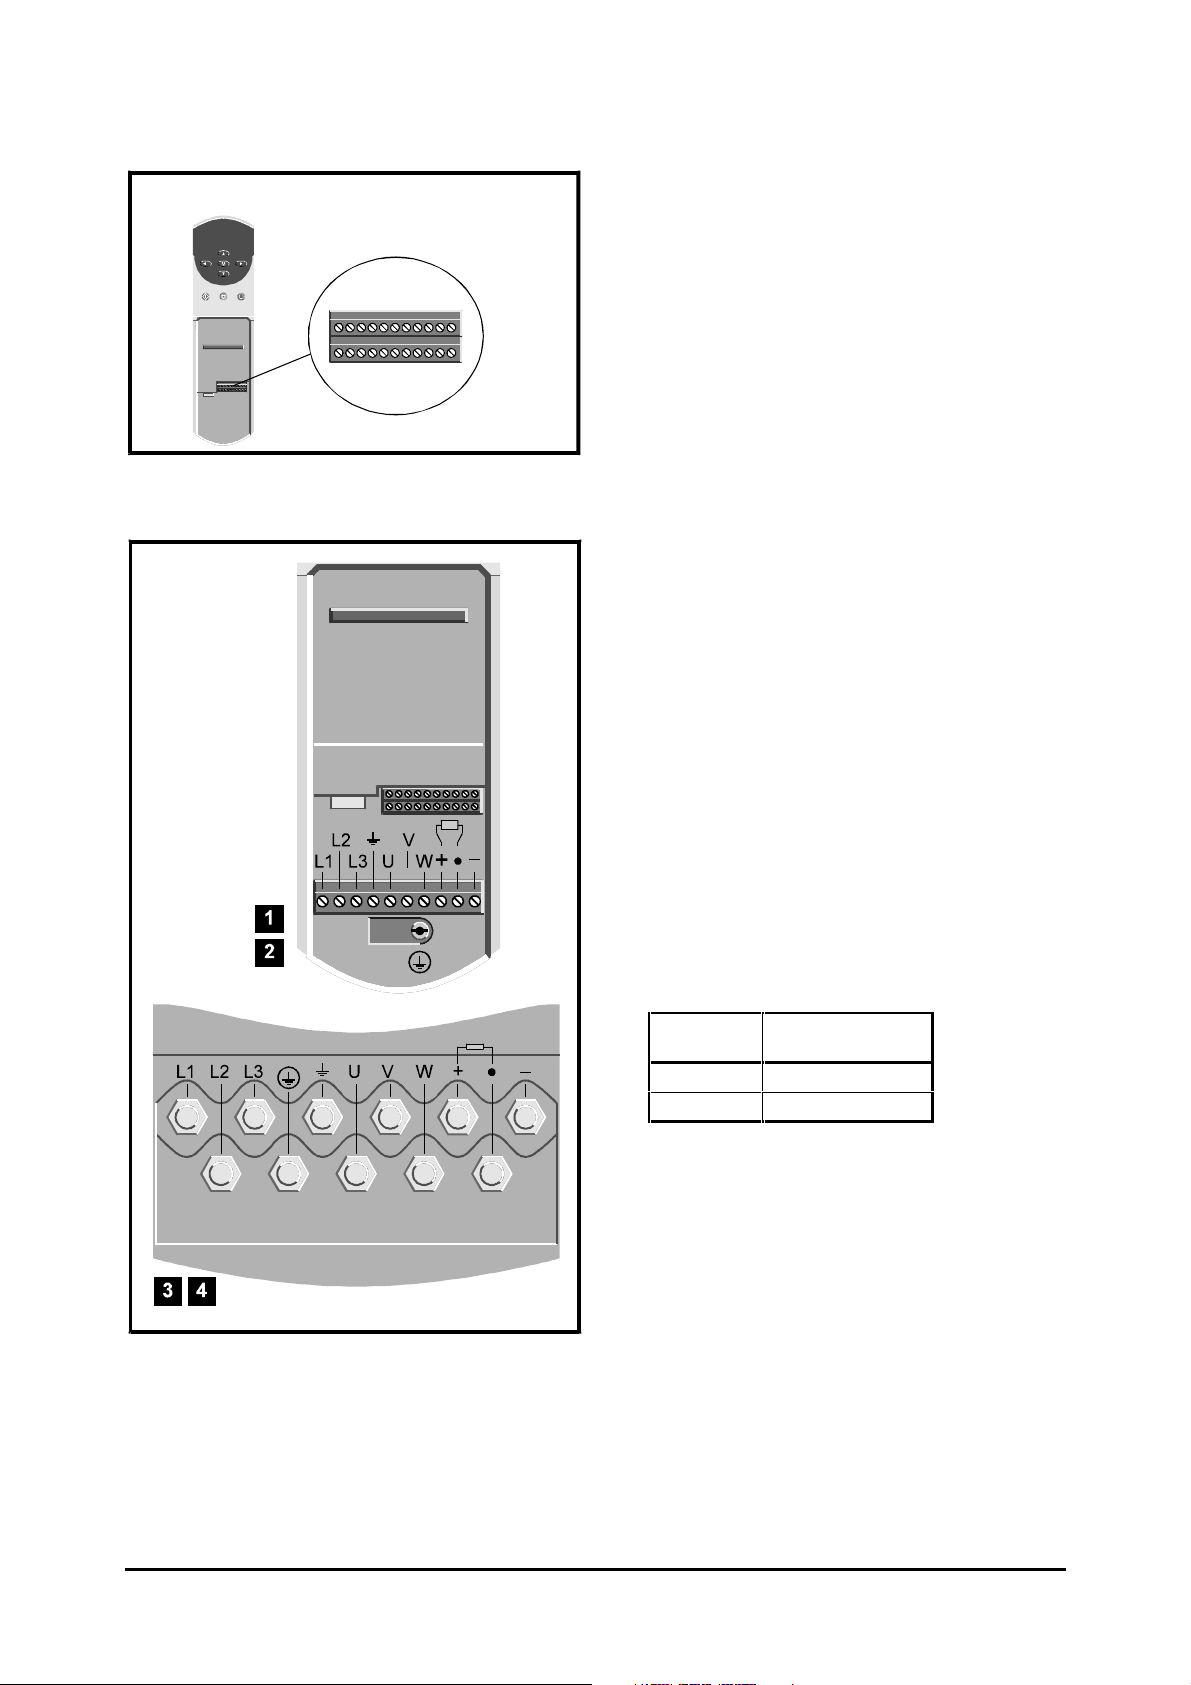
Figure 2–2 Location of the signal connector
1. Observe the safety warnings and cautions given
in Chapter 1 Safety information of the Installation
Guide and in this chapter.
2. Refer to the following:
• Chapter 2 of the Installation Guide in order
to install the Drive
• Figure 2–2 for the location of the
signal connector
• Figure 2–3 for the locations of the
power connections
• Figure 2–5 or 2–6 in this chapter in order to
make the signal and power connections for
operation in Terminal or Keypad mode.
Note that Macros 2, 3, 4, 5, 6 operate only in
Terminal mode. If one of these macro
configurations is to be enabled after the
initial setting up covered in this chapter, you
may wish to set up the Drive now in
Terminal mode in order to learn how to
operate it in this mode.
Signal connector for all models The two
terminal blocks of the signal connector can be
unplugged from the Drive by pulling them
downward.
Figure 2–3 Locations of the power connectors
Power connector for model sizes 1
and 2 The power connector can be unplugged
from the Drive by pulling it downward.
Power connections to model sizes 3
and 4 The power connections are made to
M10 studs located in the power section of the
Drive.
3. Note that the default user-interface mode is
as follows:
Continent User-interface
mode
EUR Terminal
USA Keypad
(Instructions for changing the user-interface
mode are given later.)
2-2 Getting Started
Commander GP User Guide
Issue code: gpxu2
Page 13
4. When connecting a motor to the Drive, observe
the following:
• Preferably the motor should be identical to
the motor that is to be used in the
application, but this is not essential.
• The motor shaft must not be attached to
any equipment, or exposed.
5. No motor thermistor connection is required at
this stage, but a thermistor will be required
later if the Drive is to be operated in any macro
configuration except Macros 1 and 5. When
Macro 1 or Macro 5 is enabled, the thermistor is
ignored by the Drive. (Instructions for
connecting a motor thermistor to the signal
connector are given for each macro
configuration in Chapter 3 Setting Up the Drive.)
After having made control
connections, carefully check
Warning
that terminal 30 is open-circuit
to ensure the Drive is in the
Stop state when the
AC supply
is first connected.
6. After re-fitting the terminal cover, connect the
Drive to the
AC supply.
Commander GP User Guide
Issue code: gpxu2
Getting Started 2-3
Page 14
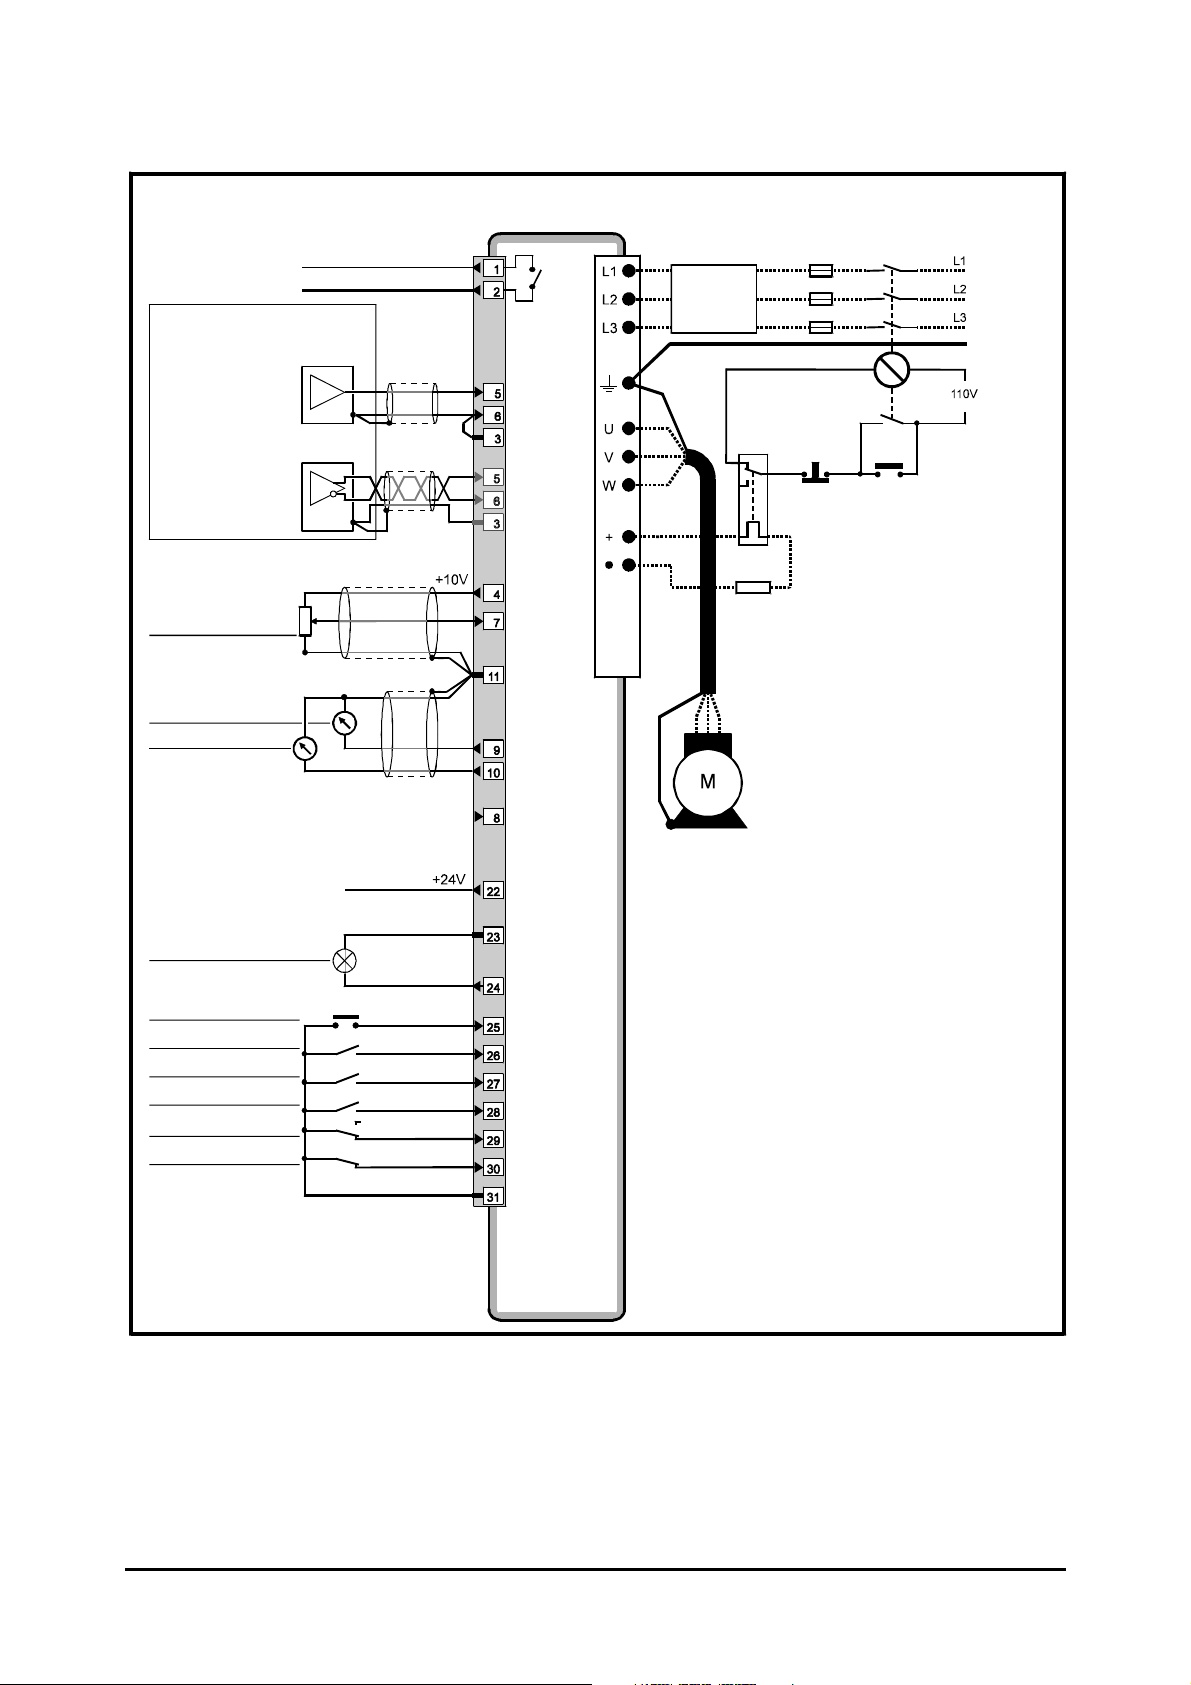
Refer to the Installation Guide for
cable sizes and fuse ratings
Status relay
Drive healthy
Analog frequency reference 1
(remote)
Connections for
single-ended input
Connections for
differential input signal
Analog frequency
reference 2
(local)
SPEED
TORQUE
signal
0V common
0V common
0V common
Signal
connector
Power
terminals
Optional
RFI filter
Thermal
protection
device
Stop
Optional braking resistor
Refer to the Installation Guide for sizing
of the optional braking resistor
Start /
Reset
0V common
AT SPEED
RESET
JOG SELECT
RUN FORWARD
RUN REVERSE
LOCAL / REMOTE
External trip
REMOTE
LOCAL
0V common
Figure 2–5 Power connections, and signal connections for Terminal mode (Macro 1 only)
2-4 Getting Started
Commander GP User Guide
Issue code: gpxu2
Page 15
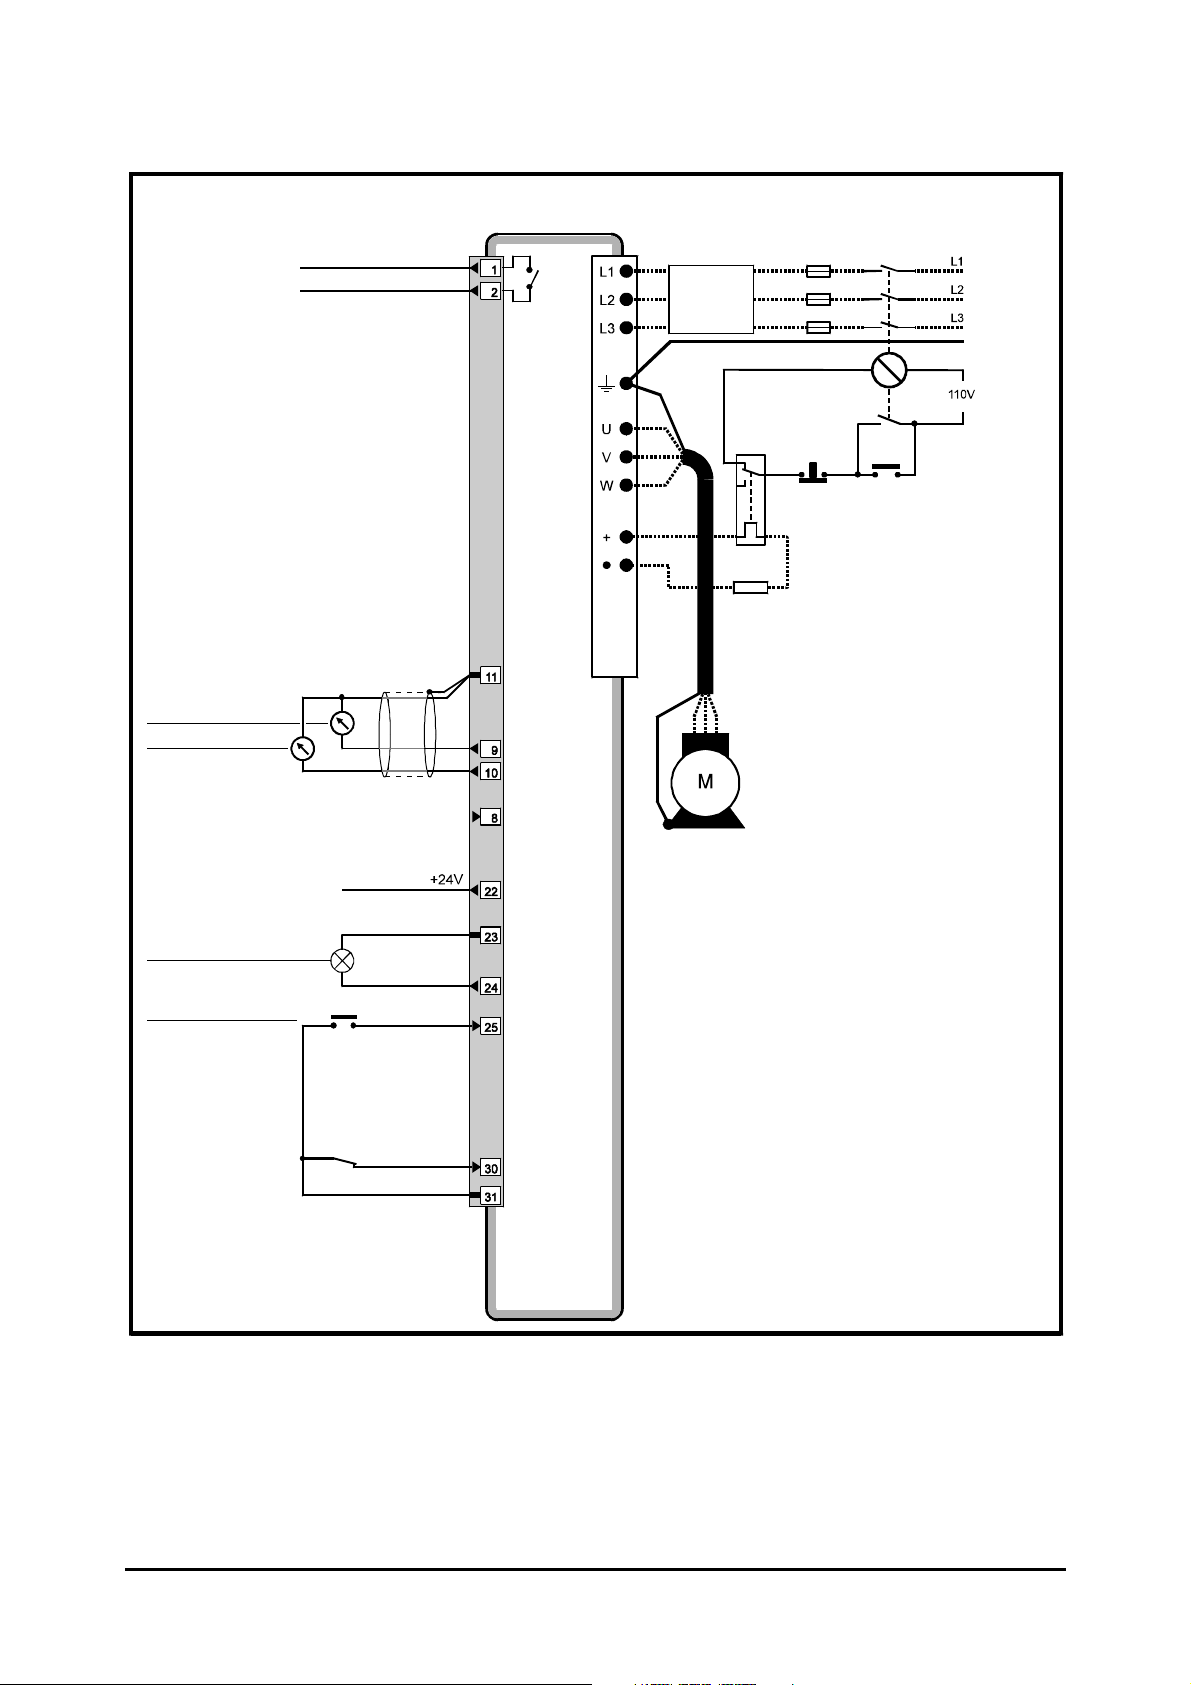
Refer to the Installation Guide for
cable sizes and fuse ratings
Status relay
Drive healthy
SPEED
TORQUE
0V common
Signal
connector
Encoder
Power
Optional
RFI filter
Thermal
protection
device
Stop Start /
Optional braking resistor
Refer to the Installation Guide for sizing
of the optional braking resistor
Reset
0V common
AT SPEED
RESET
External trip
0V common
Figure 2–6 Power connections, and signal connections for Keypad mode (Macro 1 only)
Commander GP User Guide
Issue code: gpxu2
Getting Started 2-5
Page 16
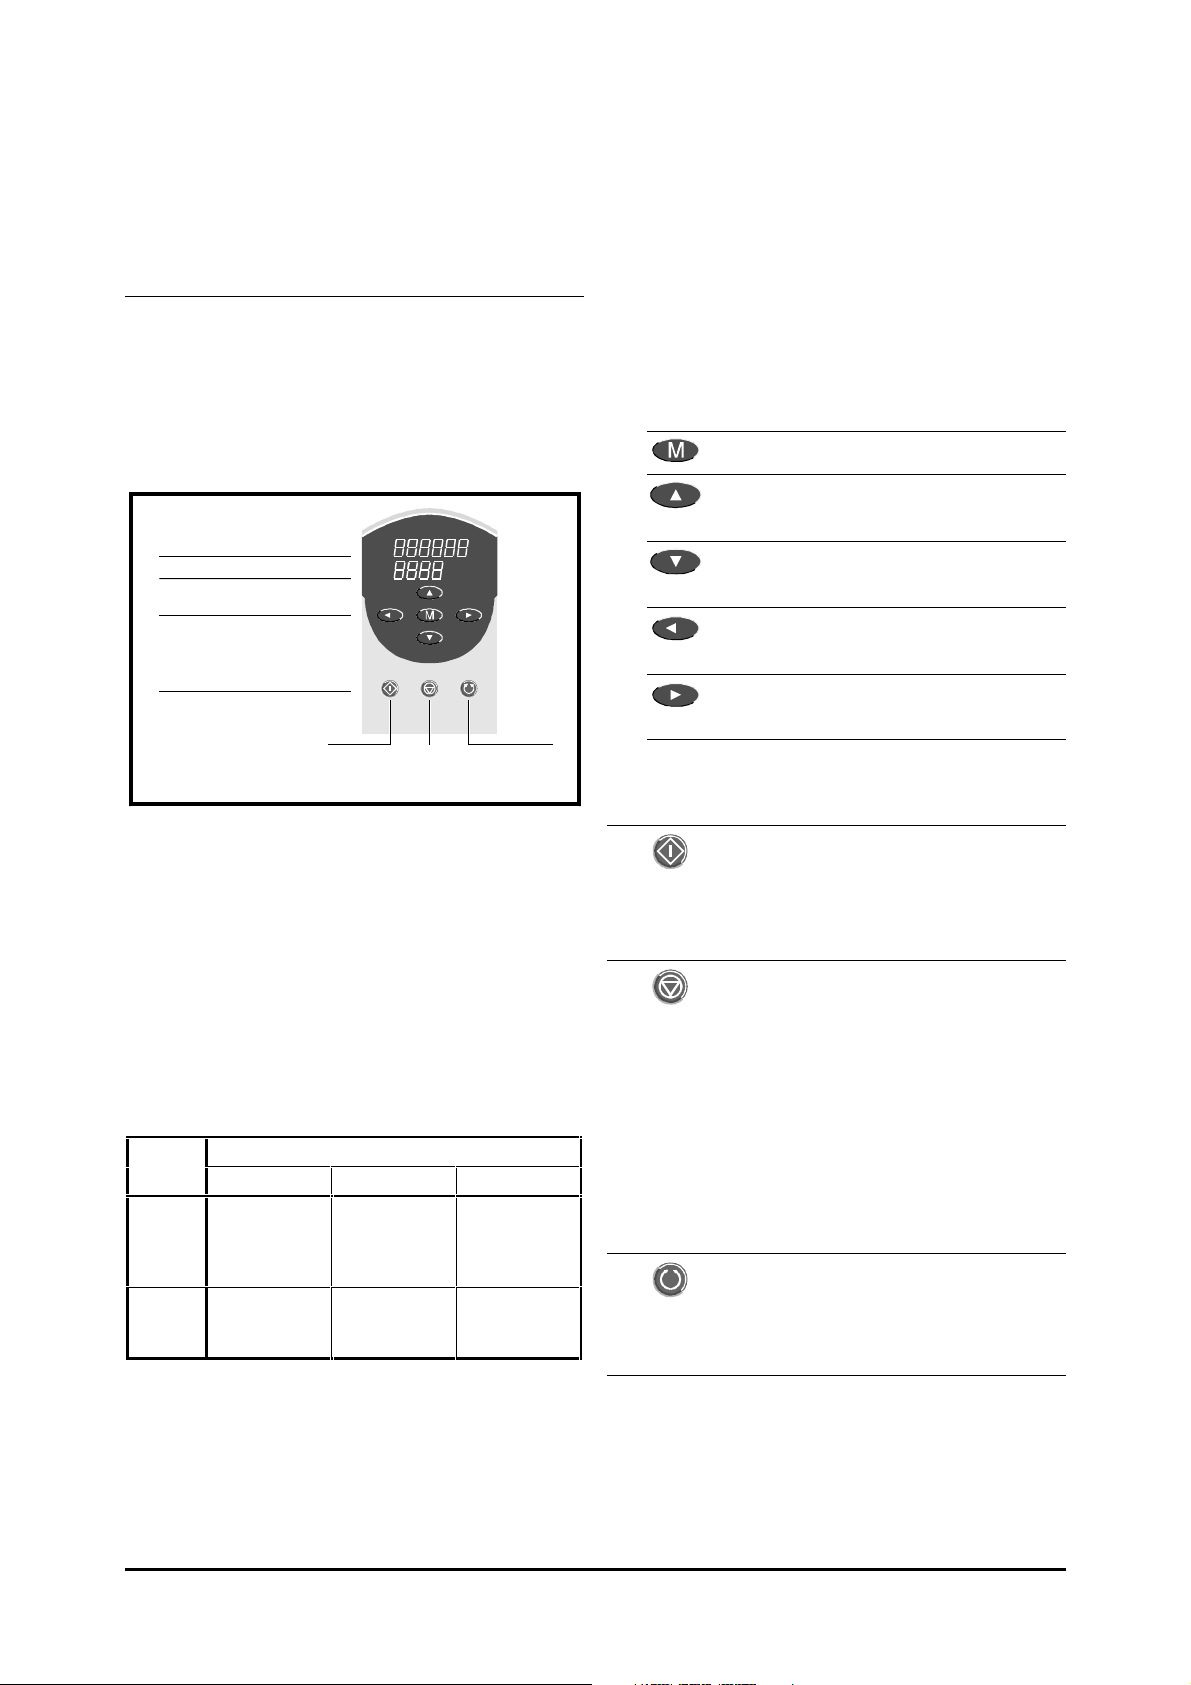
2.3 Introduction to the
display and keypad
Display and keypad
The display and keypad are used for the following:
• Reading and changing the values of software
parameters that are used to configure,
control and monitor the Drive
• Displaying the operating status of the Drive
• Displaying fault and trip codes
Upper display
Lower display
Programming keys
Control keys
Run Stop
Reset
Figure 2–7 Display and keypad
Forward /
Reverse
Programming keys
These are used for the following:
• Changing the mode of operation of the
display
• Selecting a parameter to edit
• Editing the selected parameter
• Saving new values given to parameters
The functions of the programming keys are as
follows:
Change the display mode
Select a parameter
Increase the value of a digit
Select a parameter
Decrease the value of a digit
Display the parameter number
Select the next left display digit
Display the parameter number
Select the next right display digit
Control keys
The functions of the control keys are as follows:
Display
The display has three display modes as follows...
• Status mode
Used to indicate the status of the Drive
• Parameter mode
Used for selecting a parameter to edit
• Edit mode
Used for editing the selected parameter
... and shows the following:
Display Display mode
Status Parameter Edit
Upper Value of
parameter (
Lower Status of the
Drive
Value of
0)
parameter (0)
Parameter
number (0.10)
rdY
Operating instructions for the display and keypad
are given in Appendix A Programming Instructions.
Value of
parameter (0)
(selected digit
flashes)
Parameter
number (0.10)
(RUN) Start the Drive running.
The RUN key is active only when the Drive is
operating in Keypad mode (parameter 0.05
Reference select set at 4).
(STOP–RESET) The three functions of
this key are as follows:
• Stop the Drive
• Reset the Drive after it has tripped
• Make new parameter-values take effect
The STOP-RESET key is active when the Drive
is operating in Keypad mode. This key acts only
as RESET when the Drive is operating in
Terminal mode (parameter 0.05 Reference select
set at 0, 1, 2, 3 or 5).
(FWD/REV) Change the direction of
rotation of the motor. (This is not enabled by
default, and is described later in this chapter in
Enabling reverse direction in Keypad mode.)
2-6 Getting Started
Commander GP User Guide
Issue code: gpxu2
Page 17
Resetting the Drive
Types of parameter
Terminal mode
When the Drive is stopped, press:
Alternatively, close the RESET contact (see
Figure 2–5).
Keypad mode
When the Drive is stopped, press:
When the Drive is running, press and hold...
... then press:
Release both keys at the same time.
2.4 Working with
software parameters
Parameters
The software parameters are contained in a menu
named Menu 0. Each parameter has a number as
well as a name. These are represented in this User
Guide as (for example, parameter 03 in Menu 0):
0.03 Acceleration rate
When the value of a parameter is referred to, it is
indicated as [0.03].
Variable and bit parameters
There are two types of parameter, as follows:
• Bit parameters
• Variable parameters
Bit parameters can be set at 0 or 1 to carry out the
following:
• Enable and disable functions
• Select from two options
Variable parameters can be set at any value within
the specified range to carry out the following:
• Enter values
• Select from more than two options
No distinction is made in the parameter numbering
system between variable and bit parameters. When
a bit parameter is selected on the Drive display, the
word bit appears.
Read–write and read-only
Both types of parameter can be as follows:
• Read–write (
• Read-only (
Read–write parameters are programmable by the
user. Read-only parameters are for information
purposes; they cannot be programmed.
The settings of read–write and read-only
parameters can be read on the display or remotely
using serial communications.
RW)
RO)
Adjusting parameter values
Instructions on adjusting parameter values are given
in Appendix A Programming Instructions.
Commander GP User Guide
Issue code: gpxu2
Making new values effective,
and saving them
The new value of most parameters takes effect as
soon as it is entered. Some parameters (such as the
destination-selection parameters for the analog
inputs) require the Drive to be reset before their
new values take effect.
Unless a save procedure is carried out, the new value
will be lost when the
the Drive (described in Saving new parameter-values
in Appendix A Programming Instructions).
AC supply is disconnected from
Getting Started 2-7
Page 18
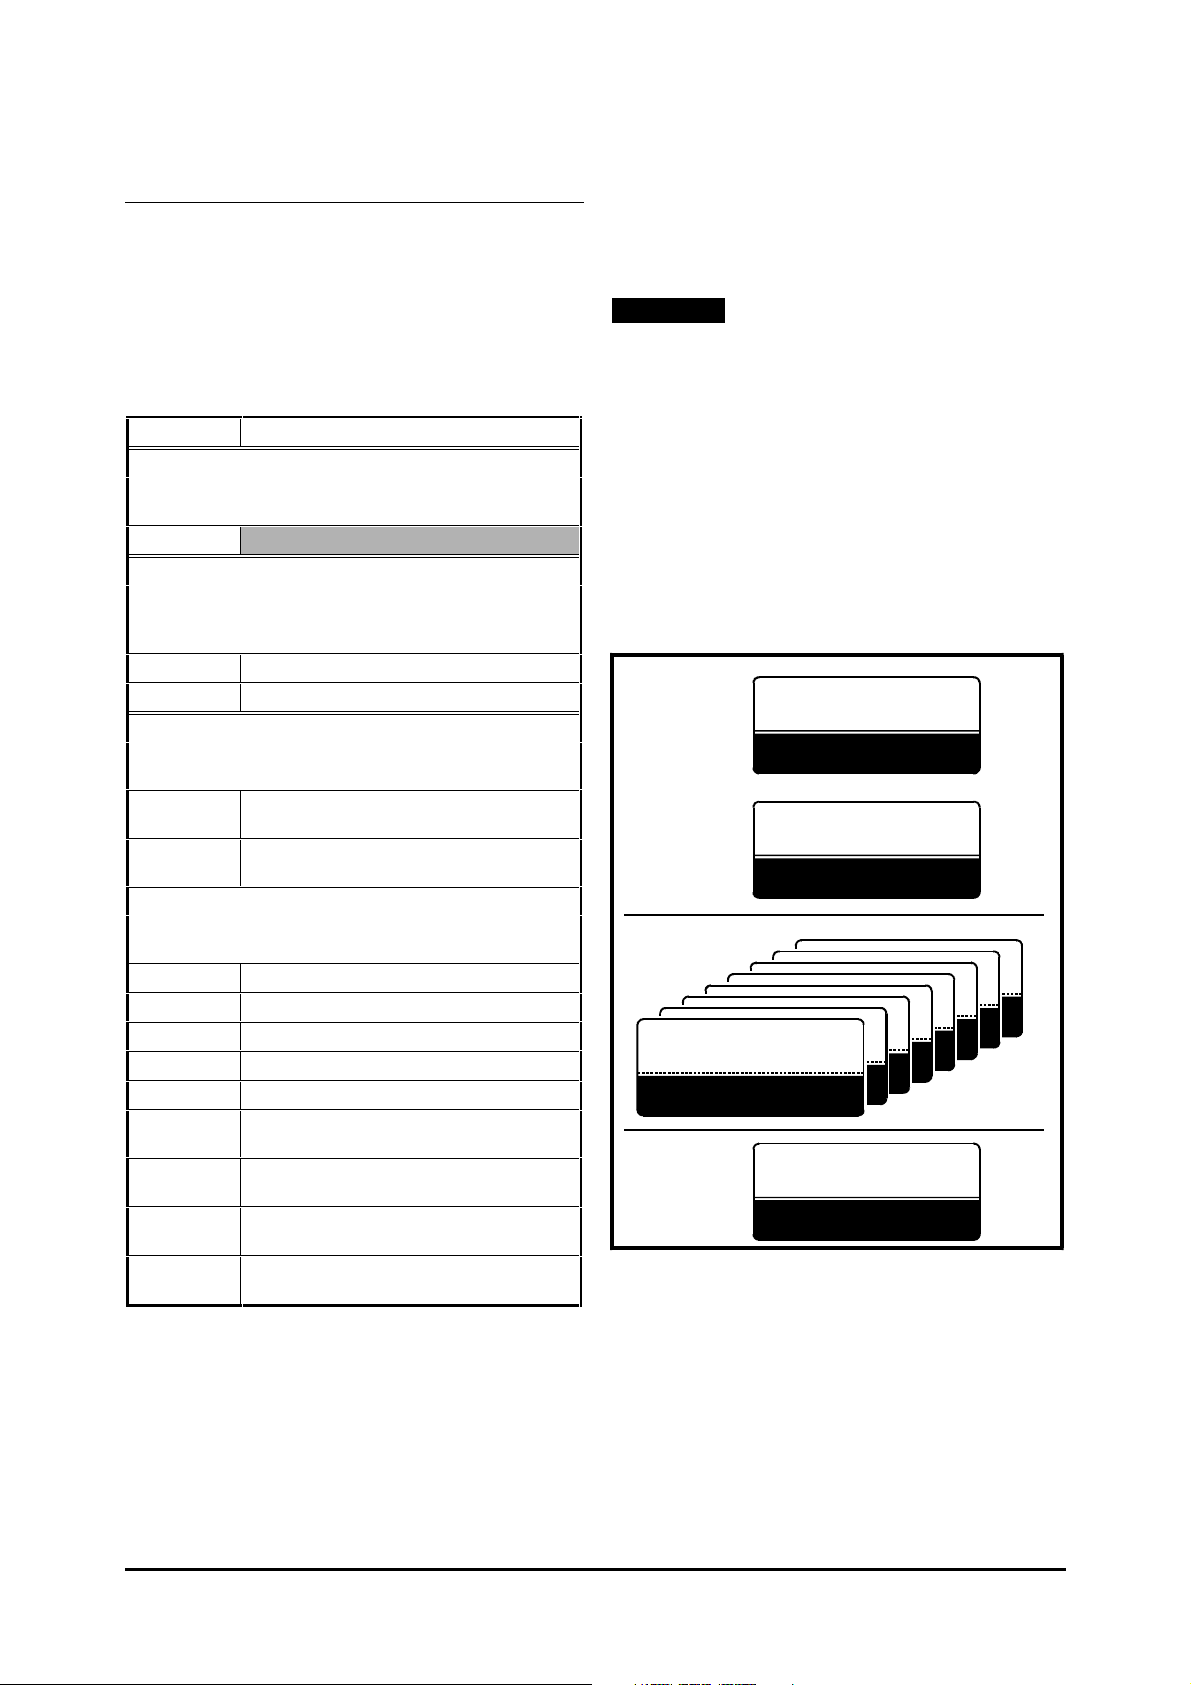
Parameter 0.00
Parameter 0.00 is a special read–write parameter
that is used for the following:
• Saving new values given to parameters
• Controlling security
• Enabling macro configurations
These functions are controlled by the user entering
specific values, as shown below:
Value Function
Saving new parameter-values
The Drive can be running or stopped
(described in Appendix A Operating Instructions)
1000
Controlling security
The Drive can be running or stopped
(described in Appendix B Security and Accessing the
Advanced Parameters)
0 ~ 255 User security code
2000 Lock security
Restoring the Drive to a default configuration
The Drive must be stopped
(described later in this chapter)
1233 Restore default values to all parameters for
1244 Restore default values to all parameters for
Selecting Macros 0 to 7
The Drive must be stopped
(described in Chapter 3 Setting Up the Drive)
2001 Macro 1 Easy mode
2002 Macro 2 Motorized potentiometer
2003 Macro 3 Preset speeds
2004 Macro 4 Torque control
2005 Macro 5 PID (set-point) control
2006 Macro 6
2007 Macro 7
2009 Macro 0 General purpose
2010 Macro 0 General purpose
The Drive must be reset to make a newly selected
function or configuration take effect.
50Hz
AC supply frequency (Europe)
60Hz
AC supply frequency (USA)
Axis-limit control
Brake control
(USA default configuration)
(EUR default configuration)
2.5 How macro configurations
change the arrangement of
the Menu 0 parameters
Note
Do not confuse the term Macro with the
term Menu. Menu 0 contains parameters;
macro configurations re-define some of
these parameters to perform specific
functions. Menu 0 always exists, but is
affected by the macro configuration that is
enabled.
Only one macro configuration can be
enabled at a time.
Menu 0 contains 51 parameters which are arranged
in four groups, as shown in Figure 2–8.
Common to
all macros
Configuration and saving
parameter
Fixed-function parameters
Specific to
each macro
0.11 ~ 0.30
Re-programmable parameters
Common
to all
macros
Fixed-function parameters
Figure 2–8 How the Menu 0 parameters are
grouped and the relationship with
the macro configurations
0.00
0.01 ~ 0.10
Macro 0
1
0.31 ~ 0.50
7
6
5
4
3
2
Instructions for using parameter 0.00 are given at
the appropriate places in this User Guide
2-8 Getting Started
Commander GP User Guide
Issue code: gpxu2
Page 19
Macro 0
2.6 Initial setting up
When Macro 0 is enabled, the re-programmable
parameters have their default functions.
Macro 1
When Macro 1 Easy Mode is enabled, none of the
re-programmable parameters are available.
Macros 2 to 7
When one of these macro configurations is enabled,
the functions of some re-programmable parameters
are specific to the macro configuration.
Other factors that affect the
re-programmable parameters
In addition to the changes caused by the macro
configurations, the functions of some
re-programmable parameters are changed by the
default configuration of the Drive (EUR or USA)
These are are shown in Appendix D Menu 0
Parameters.
Where to find information on
parameters
The functions of the parameters are listed for each
macro configuration in Chapter 3 Setting Up the Drive.
The functions of the parameters for each macro
configuration are described in detail in Appendix D
Menu 0 Parameters.
Noting the user values
A parameter table for each macro configuration in
Chapter 3 Setting Up the Drive has a column for you
to note the values entered in the parameters.
Restoring the Drive
to a default configuration
Do not attempt to restore the
Drive to a default
configuration when the Drive is
Warning
Restoring the Drive to a default configuration is not
essential for initial setting up, but should be used
for achieving the following:
• When one of the macros 2 to 7 is currently
• Intentionally restoring all parameters to
• Changing (or re-applying) the default
1. Enter either of the following values in
parameter 0.00:
EUR> (Europe, 50Hz
USA> (USA, 60Hz
running.
Restoring the Drive to a
default configuration enables
Macro 0 and returns all
parameters to their default
values including the motor
parameters. (If any one of the
macros 1 to 7 has been enabled,
the Drive still reverts to
Macro 0.)
After restoring the Drive to a
default configuration, it will be
necessary for the required
parameter values to be
re-entered before the Drive is
next run.
enabled, and a different macro
configuration is required
their default values (this includes the motor
parameters)
configuration for the continent in which the
Drive is to be used
AC supply): 1233
AC supply): 1244
Commander GP User Guide
Issue code: gpxu2
2. Press
3. Set 0.00 at 1000.
4. Press
(RESET key).
(RESET key).
Getting Started 2-9
Page 20
The following conditions now apply:
• All the default values (including those of the
motor parameters) take effect
• Macro 0 is enabled
If required, any other macro configuration can be
enabled.
Enabling Macro 1
Do not attempt to enable any
macro configuration when the
Drive is running.
Warning
Note
If the Drive is to be operated in Macro 1 or
5 and a braking resistor is to be used, now
set parameter 0.15 at FASt. Then follow
the instructions below.
The setting of parameter 0.15 must be
changed now because the function of this
parameter is changed when one of these
macro configurations is enabled.
1. Set parameter 0.00 at 2001.
2. Reset the Drive.
The configuration layers (see Chapter 1 Introduction)
are now as follows:
1. Appropriate default configuration for the
continent (EUR or USA)
2. Macro 1 Easy mode
Configuring the Drive for the motor
The values of the motor
parameters affect the
Warning
Caution
protection of the motor and
the safety of the system.
When entering values, make
sure they are relevant to the
motor that is to be used. The
default values in the Drive
should not be relied upon.
The motor parameters should
be set to within 10% of the
required values for the motor.
Failure to do this may result in
poor response.
It is essential that the correct
value is entered in parameter
0.46 Motor – rated current. This
affects the thermal protection
of the motor.
Keep a note of the values given
to the motor parameters, since
motor parameters are restored
to their default values when
the Drive is restored to a
default configuration (this
must be done if the Drive has
been used with Macro 2 to 7
enabled and a different macro
configuration is to be enabled)
2-10 Getting Started
Commander GP User Guide
Issue code: gpxu2
Page 21
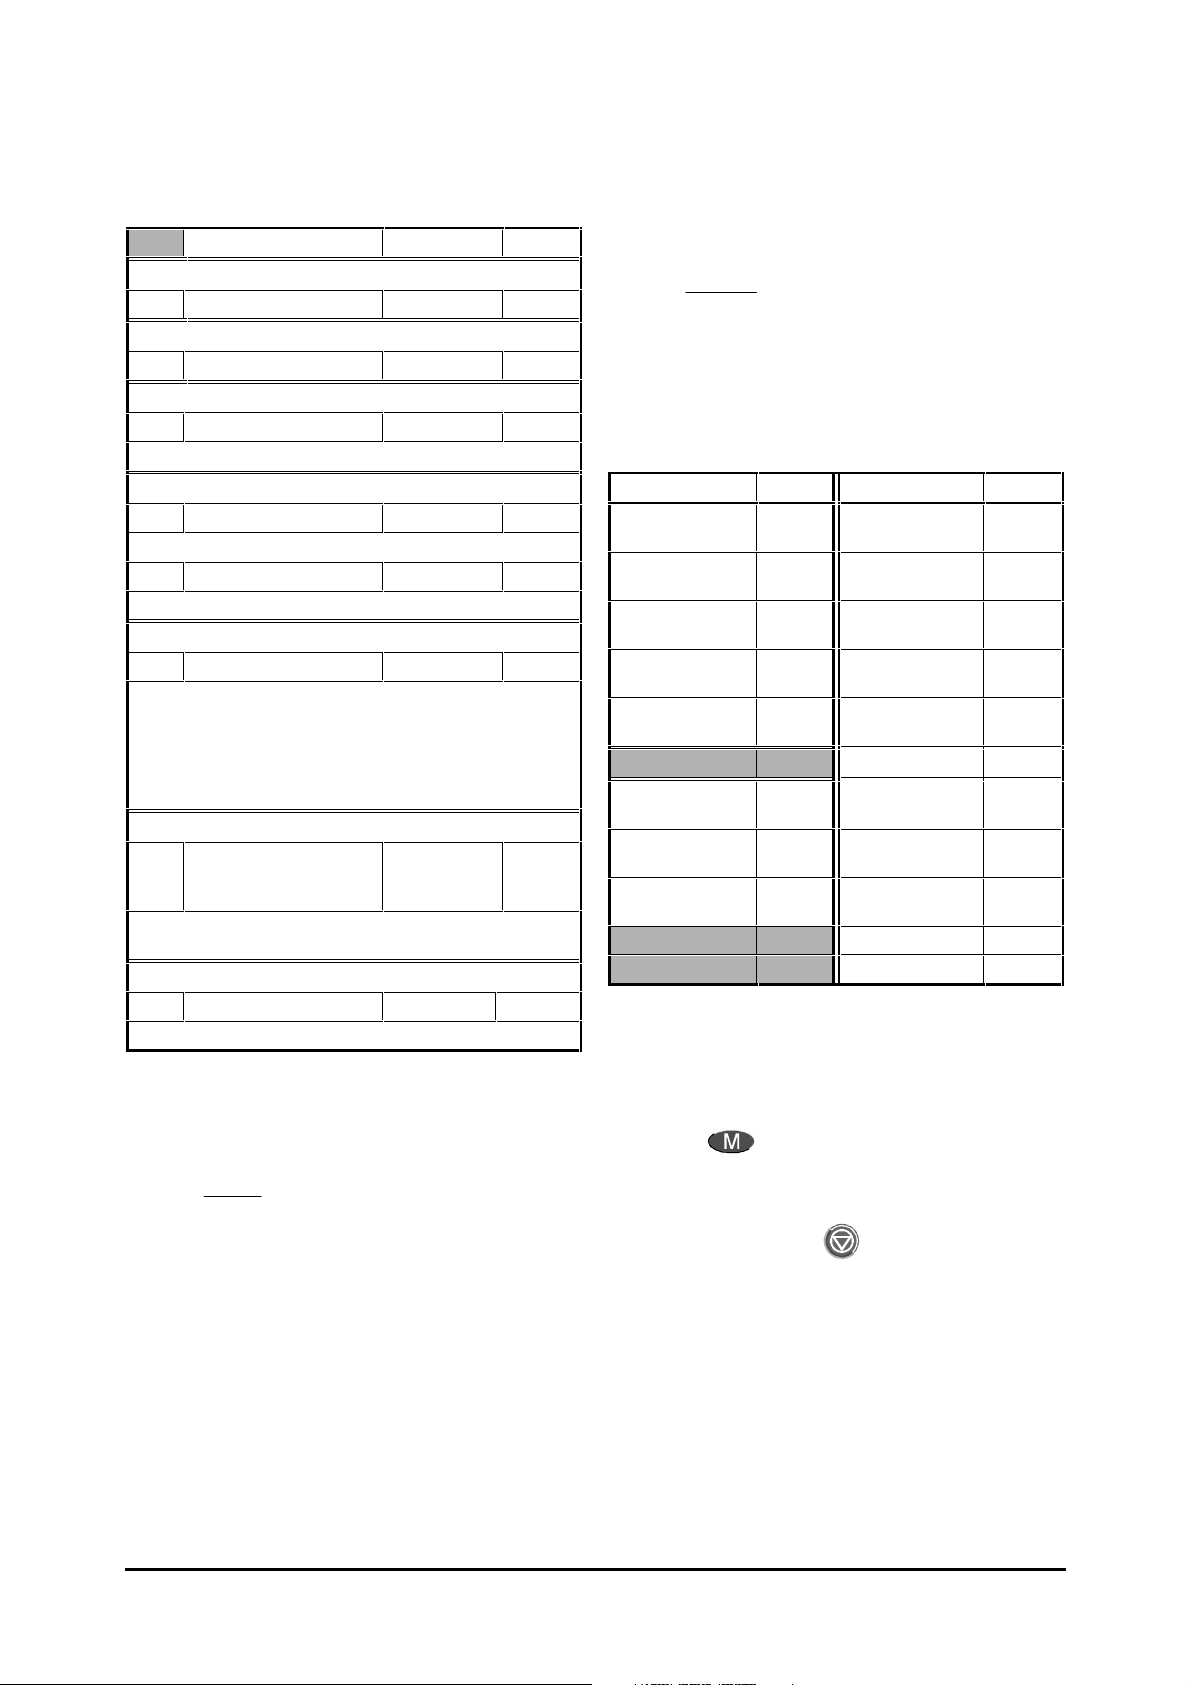
Enter the motor ratings in the motor parameters of
Model
GPD 3201
GPD 3401
GPD 3402
GPD 3202
GPD 3403
GPD 3203
GPD 3404
GPD 3405
GPD 3204
GPD 4401
GPD 4402
GPD 4403
GPD 4404
GPD 4405
the Drive, as follows:
Default value Range Unit
0.41 PWM switching frequency
3 3, 4.5, 6, 9, 12 kHz
0.42 Motor – number of poles
4 2 ~ 32 poles
0.43 Motor – power factor
0.92 0 ~ 1.0
(See Autotune later in this chapter)
0.44 Motor – rated voltage (Standard models)
400 (EUR)460 (USA) 0 ~ 480 V
0.44 Motor – rated voltage (LV models)
220 0 ~ 240 V
Enter the rated value.
0.45 Motor – rated speed
0 0 ~ 6000 RPM
When 0.45 is set at 0, no slip compensation is applied by
the Drive. When a value greater than zero is entered, slip
compensation is applied but instability can occur with
motor loads that have predominant inertia. To avoid this
instability, set 0.45 at 0. The value can be changed at a
later time.
0.46 Motor – rated current
FLC
(see the following Values
of FLC table)
Ensure that the motor current-rating applies to the
winding configuration used.
0.47 Motor – rated frequency
50 (EUR) 60 (USA) 0 ~ 1000.0 Hz
Enter the rated value.
0 ~ FLC A
When the number of motor poles
is not known
Example
Rated motor speed: 1450 RPM
AC
supply frequency: 50Hz
P ==
××==50 120
1450
414.
Therefore, the number of poles = 4
(The inaccuracy of the calculation is caused by slip,
in this case 50
RPM.)
Values of FLC
Model FLC (A)
GPD 1201
GPD 1401
GPD 1202
GPD 1402
GPD 1203
GPD 1403
GPD 1204
GPD 1404
GPD 1205
GPD 1405
GPD 2201
GPD 2401
GPD 2202
GPD 2402
GPD 2203
GPD 2403
2.1
2.8
3.8
5.6
9.5
12
16
25
FLC (A)
34
40
46
60
70
74
96
124
156
180
202
Saving the values
Use the following procedure:
1. Set parameter 0.00 at 1000.
Calculate the number of poles from the following:
f
120
××
P
==
N
Where:
AC supply frequency
f
N Rated full-load speed of the motor
The number of poles will be the whole number
immediately below the value of P. Enter this whole
number in 0.42.
Commander GP User Guide
Issue code: gpxu2
2. Press
. The display returns to Parameter
mode. Do not press any keys within eight
seconds; the display then enters Status mode.
3. Momentarily press
to reset the Drive.
Getting Started 2-11
Page 22
Autotune
Autotune is a sequence of tests performed by the
Drive. The results of the tests are subsequently
used by the Drive for controlling the motor.
Autotune should be used after the motor
parameters have been entered, but before the Drive
is used. Normally (and if the motor is not changed),
Autotune needs performing only once.
During the following
procedures, the Drive will
Warning
Note
To stop the test at any time, press .
The motor will then coast to a stand-still
and the test will not be completed.
If the Drive trips
If the Drive trips during the test, note the trip code
that appears on the upper display and refer to
Appendix E Diagnostics. The test will not be
completed.
Direction of rotation
power the motor and cause
the shaft to rotate at up to
2
/3 full speed. Before
starting, make sure it will be
safe for the motor to be run.
1. Ensure the motor is unloaded and at a stand-still.
2. Ensure the EXTERNAL TRIP contact is closed.
3. Follow this step only if the Drive has previously
been set up and both of the following have
occurred...
• The setting of parameter 0.07 Voltage mode
selector has been changed to Ur
• A different motor is now connected to the
Drive
... change the setting of parameter 0.07 to
Ur_I. (See Open-loop voltage control modes later
in this chapter.)
4. Disconnect, then after at least 10 seconds,
re-connect the
to measure the stator resistance of the motor
— it is essential for the Drive to be aware of the
actual value of stator resistance for Autotune
to be performed correctly).
5. Set parameter 0.40 Autotune enable at 1. The
following tests are performed:
• The motor is accelerated up to two-thirds
rated frequency in the forward direction
while the magnetizing current is measured
• The motor is decelerated to a stand-still
6. Parameter 0.43 Motor – power factor is
automatically updated.
7. Parameter 0.40 is automatically returned to zero.
AC supply (this causes the Drive
Saving the values
1. Set parameter 0.00 at 1000.
Stored charge
Warning
The motor shaft should rotate clockwise as viewed
from the free end of the shaft during Autotune. If
the shaft rotates in the reverse direction, stop the
test, remove the
connections. If required, change the motor phase
connections and repeat Autotune.
Procedure
The Drive contains capacitors
that remain charged to a
potentially lethal voltage after
AC supply has been
the
disconnected. If the Drive has
been energized, the
must be isolated at least
ten minutes before work may
continue.
AC supply and check the motor
AC supply
Note
If the settings of parameters 0.41 to 0.47
are changed by a user after Autotune has
been performed, it is essential that
Autotune is repeated.
2-12 Getting Started
2. Press
mode. Do not press any keys within eight
seconds; the display then enters Status mode.
3. Momentarily press
. The display returns to Parameter
to reset the Drive.
Changing the user-interface mode
Change the user-interface mode, as required. If jog
is required, select Terminal mode (jog is available
only in Macros 0, 1, 4).
User-interface mode Set parameter 0.05 at...
Terminal 0
Keypad 4
Note
The main function of parameter 0.05 is a
reference selector which has other settings
that operate the Drive in Terminal mode.
At this stage, do not use any of these other
settings.
Use of parameter 0.05 is described for
Macros 0 and 1 in Chapter 3 Setting Up the
Drive.
Commander GP User Guide
Issue code: gpxu2
Page 23
2.7 Operating instructions
Before completing the initial setting up of the Drive,
you will need to learn how to operate it. Refer to
the following instructions for Terminal mode or
Keypad mode, as appropriate.
Terminal mode
Variable frequency
In Terminal mode (with Macro 1), the Drive can
control the motor as follows:
• Run (forward and reverse)
• Jog/Preset frequency (forward and reverse)
1. Ensure the control signal connections shown in
Figure 2–5 are made.
2. Check that the FREQUENCY potentiometer is
set at minimum.
3. Ensure that the EXTERNAL TRIP contact is
open.
4. Connect the Drive to the
5. The display indicates as follows:
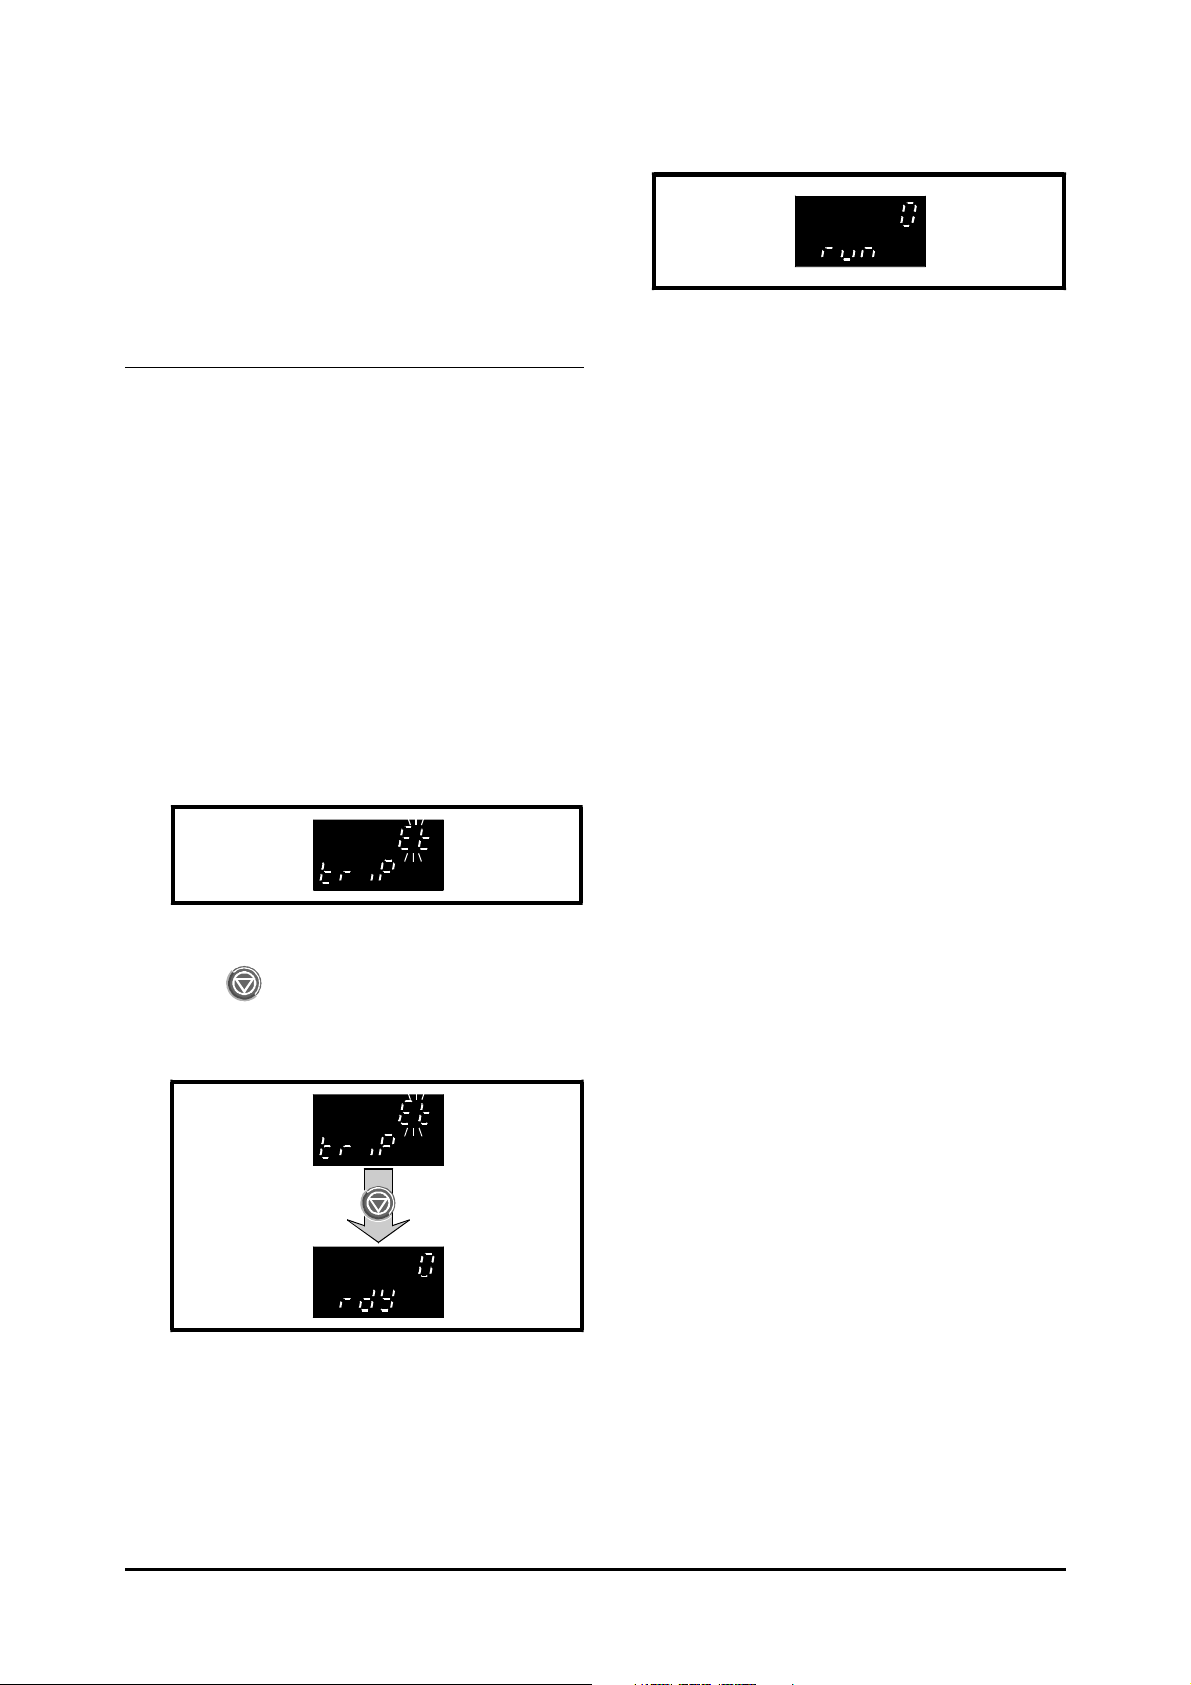
6. Close the EXTERNAL TRIP contact.
7. Press
contact.
8. The display indication changes as follows:
or momentarily close the RESET
AC supply.
11. Advance the FREQUENCY potentiometer.
12. The value shown by the upper display increases
accordingly, and the motor speed increases.
13. Open the RUN FORWARD contact. The
following occur:
• The value of the upper display reduces
to zero
• The lower display shows dEC, then rdY
• The motor speed reduces to zero
14. If required, repeat steps 10 to 13 using the
RUN REVERSE contact.
If you do not require the use of jog / preset
frequency, go to Trip and Enable later in this
chapter
Jog/Preset frequency
The jog function can be used alternatively as a
preset frequency. The default value is 1.5Hz.
1. Close the JOG/PRESET SELECT contact. Then
close the RUN FORWARD contact. It is
essential that the contacts are closed in this
order, otherwise the Drive will run forward (or
reverse) normally at variable speed.
The display indicates a fixed low speed that
cannot be changed by the FREQUENCY
potentiometer. The motor runs at this low
speed.
2. Open the RUN FORWARD contact to stop
the Drive.
9. Ensure parameter 0.10 Motor speed is displayed
(default).
10. Close the RUN FORWARD contact. The display
indicates as follows:
Commander GP User Guide
Issue code: gpxu2
3. If required, repeat steps 1 and 2 using the
RUN REVERSE contact.
4. If the JOG/PRESET SELECT contact is opened
before the RUN FORWARD or RUN REVERSE
contact, the motor speed will become
controlled by the FREQUENCY potentiometer.
Go to Trip and Enable later in this chapter
Getting Started 2-13
Page 24
Keypad mode
Motor direction in Keypad mode
In Keypad mode (with Macro 1), (FWD/REV) is
disabled by default; the Drive can control the motor
in the forward direction only. For reverse
operation, see the Commander Gp Advanced User Guide.
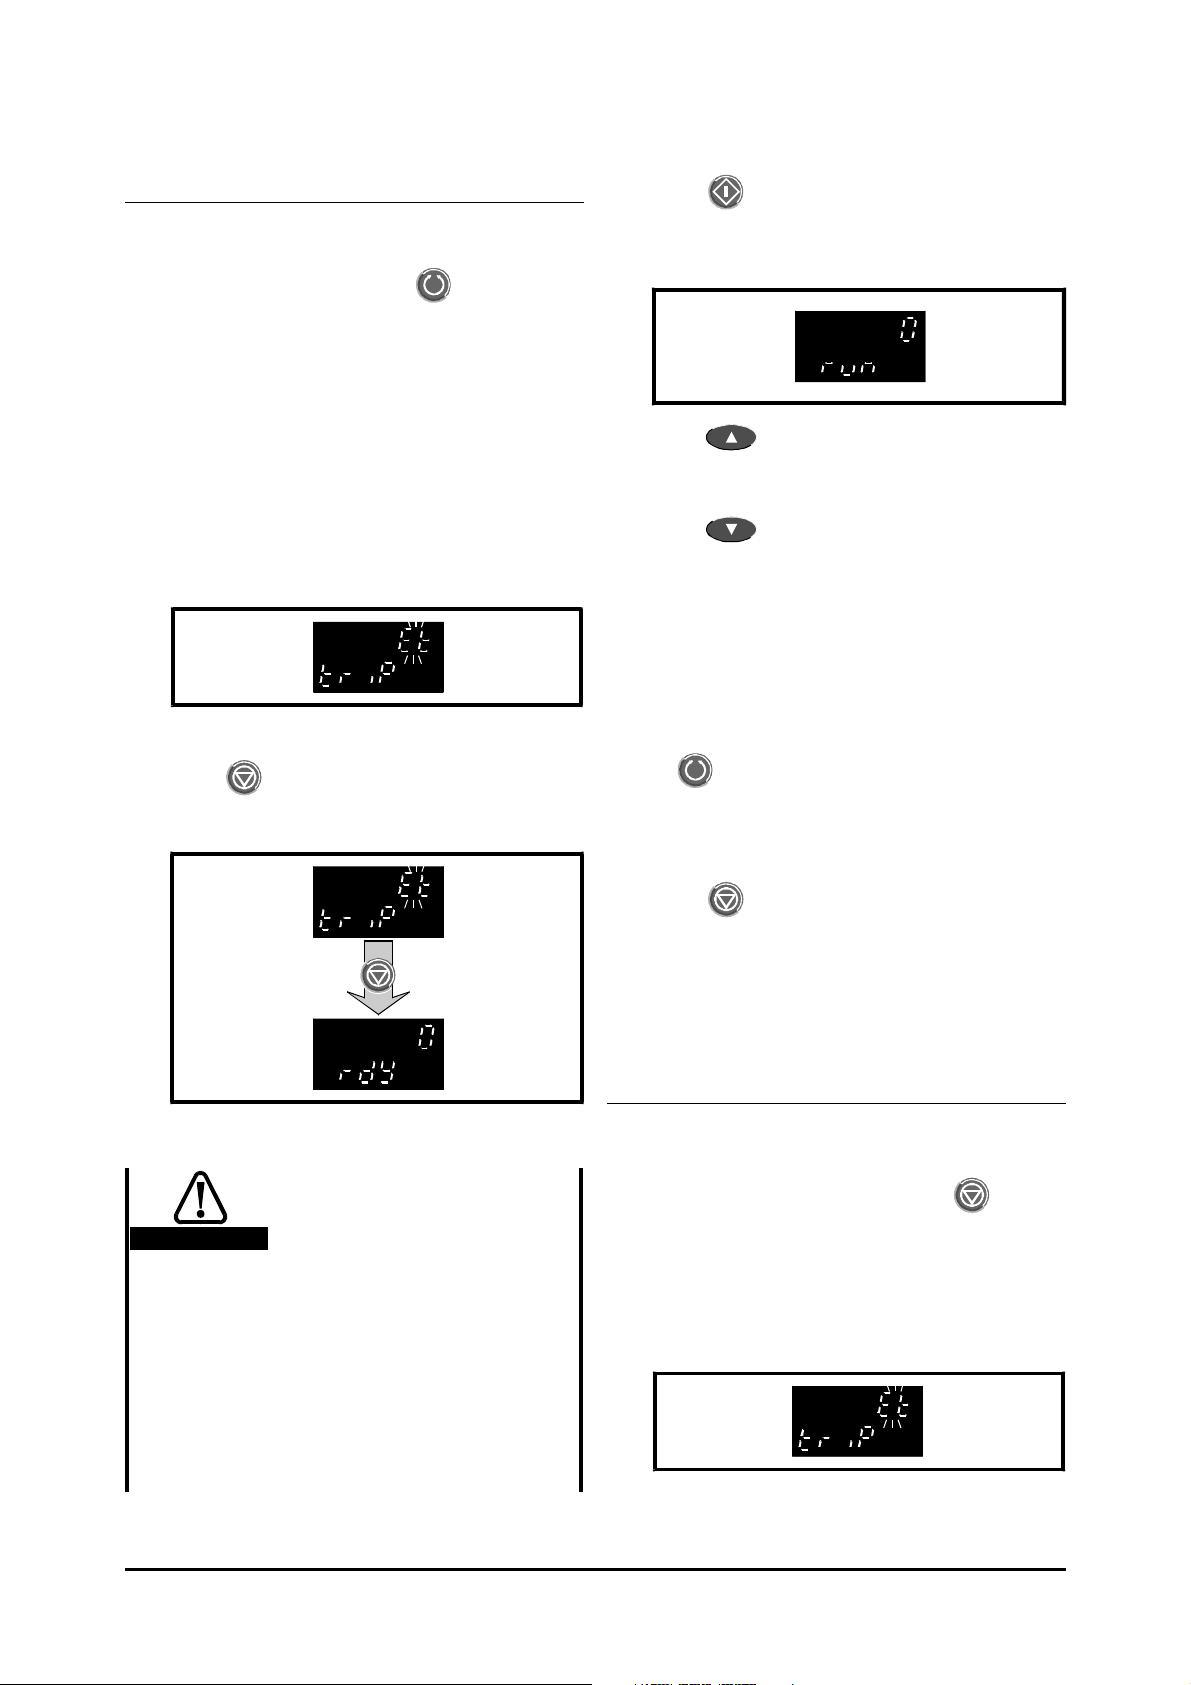
9. Press
10. The upper display should indicate zero; the
lower display will indicate as follows:
to start the Drive running.
Variable frequency
1. Ensure the control signal connections shown in
Figure 2–6 are made.
2. Ensure that the EXTERNAL TRIP contact is open.
3. Connect the Drive to the
4. The display indicates as follows:
5. Close the EXTERNAL TRIP contact.
6. Press
7. The display indication changes as follows:
AC supply.
11. Press to increase the speed. The value
of the upper display increases and the motor
speed increases.
12. Press
of the upper display decreases and the motor
speed decreases.
When the Drive is configured to accept a
bipolar speed reference, continuing to press
this key after the motor has stopped will cause
the speed to increase in the reverse direction.
(For operation with a bipolar speed reference,
see the Commander Gp Advanced User Guide.)
13. If
speed at a convenient value and then press this
key. The speed reduces to zero then increases
to the set value in the opposite direction.
14. Press
occur:
• The value of the upper display reduces
to zero
• The lower display shows dEC, then rdY
• The motor speed reduces to zero
to decrease the speed. The value
(FWD/REV) has been enabled, set the
to stop the Drive. The following
Ensure parameter 0.10 Motor speed is displayed
(default).
If the Drive has been used
previously in keypad mode,
Warning
check that the value of
parameter 0.35 is zero
before proceeding with the
next step. If it is not zero,
use the speed control keys as
appropriate to set
parameter 0.35 at zero.
If parameter 0.35 is not
zero, when the Drive is
started it will immediately
accelerate to the speed set
in this parameter.
2-14 Getting Started
Trip and enable
1. If the Drive trips, and a motor is connected, the
motor will coast. See Appendix E Diagnostics.
To clear a trip, momentarily press
Terminal mode only, momentarily close the
RESET contact.
2. If the EXTERNAL TRIP contact is opened while
the Drive is stopped or running, the Drive trips
(and the motor will coast). The display will
indicate as follows:
Commander GP User Guide
or, for
Issue code: gpxu2
Page 25
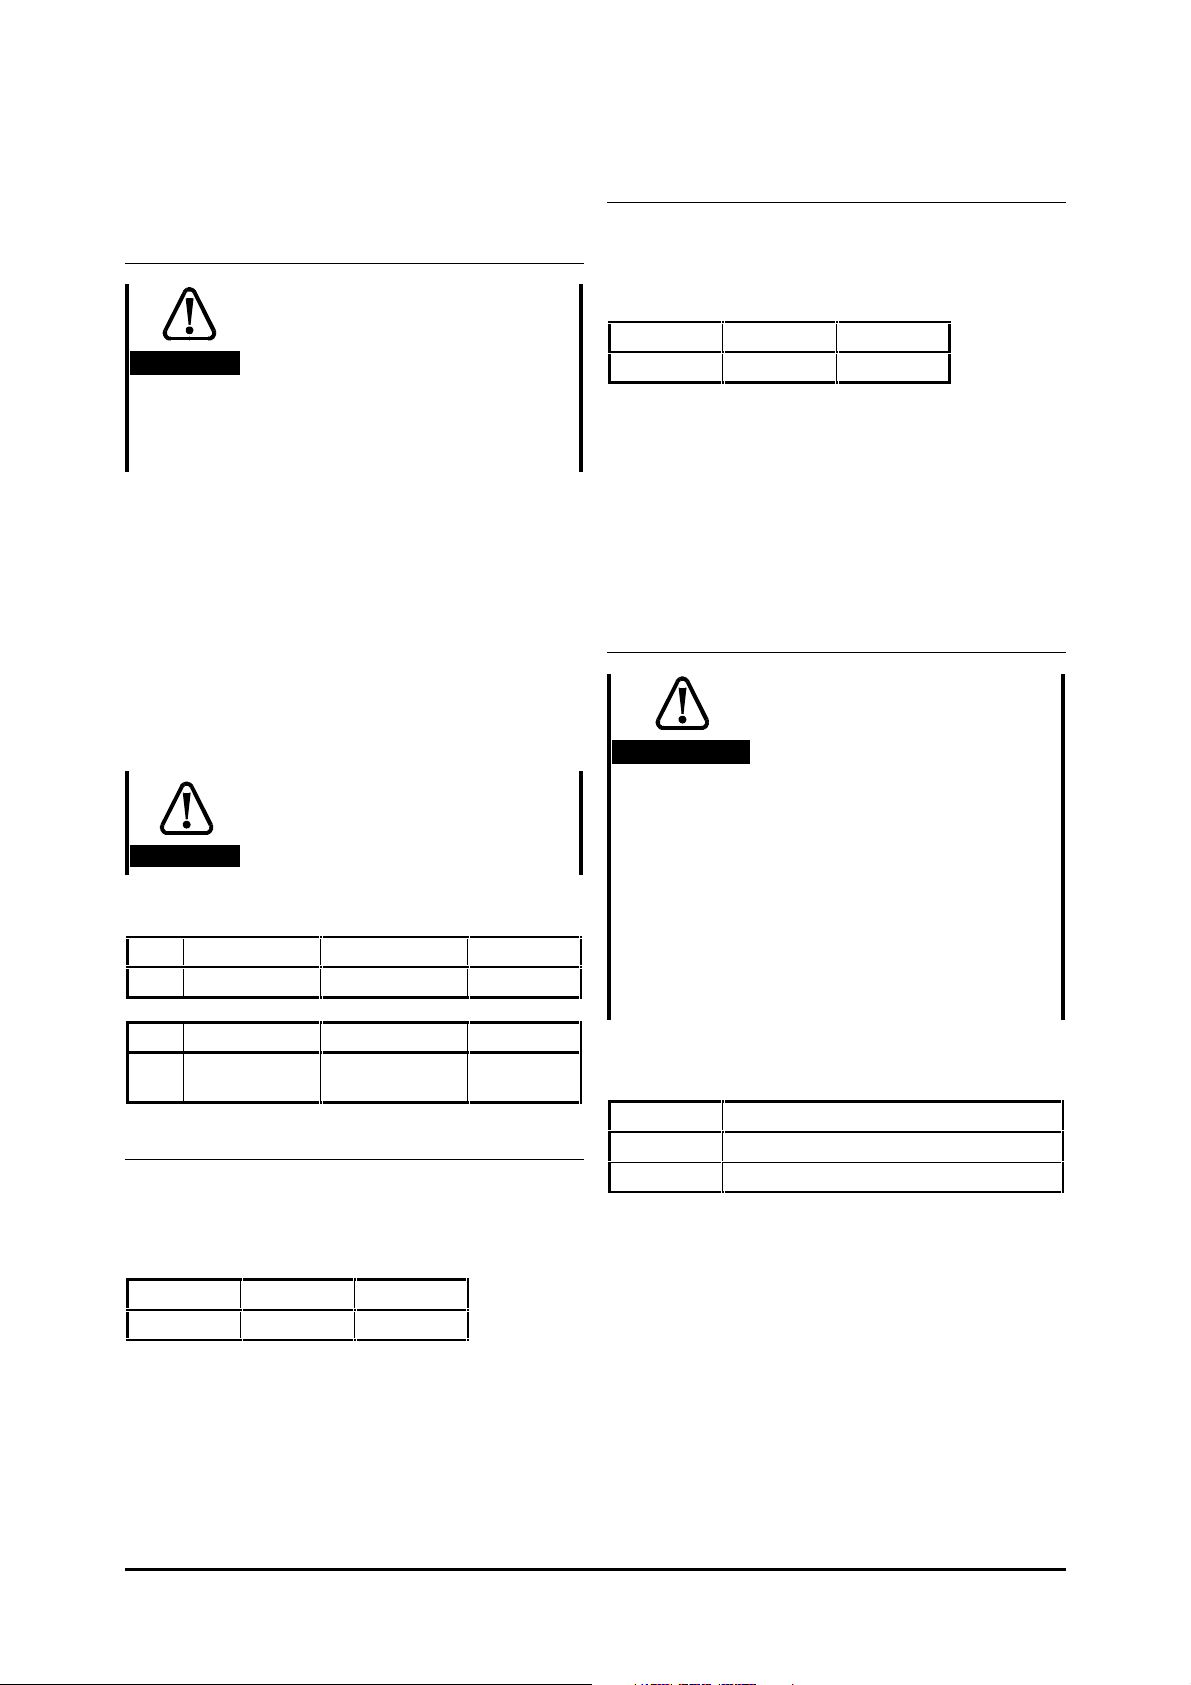
2.8 Setting up operating limits
Unit
s/100Hz
Deceleration rate
Minimum and maximum frequencies
Do not set the maximum
frequency at a value that is
excessive for the motor.
Warning
If the intended maximum
frequency affects the safety of
the machinery, additional
independent over-speed
protection must be used.
Set parameter 0.02 Maximum frequency at the
required value. When initially setting up the Drive,
leave 0.01 Minimum frequency at the default value of
zero so that the motor shaft does not rotate as
soon as a
RUN command is received. When it is
known to be safe to do so, set 0.01 at the required
value.
Note the following:
• Slip compensation can cause the output
frequency of the Drive to exceed [0.02].
For operation at motor speeds
greater than twice base speed,
contact the supplier of the
Caution
motor.
Default values and range
0.01 Default value Range Unit
0 0 ~ [0.02] Hz
0.02 Default value Range Unit
50 Hz (EUR)
60 Hz (USA)
0 ~ 1000 Hz
Acceleration rate
To adjust the acceleration rate, adjust parameter
0.03 Acceleration rate. Increase the value to
increase the time taken for acceleration (ie. reduce
the acceleration rate).
Range Default Unit
0 ~ 3200 5 s/100Hz
To adjust the deceleration rate, adjust parameter
0.04 Deceleration rate. Increase the value to
increase the time taken for deceleration (ie. reduce
the deceleration rate).
Range Default
0 ~ 3200 10
If the Drive trips when decelerating the motor and
the display indicates OU, this indicates that the
maximum permissible
DC-bus voltage has been
exceeded during braking. Increase the value of
0.04 Deceleration rate or, if a braking resistor is not
currently connected, return to Planning the
installation in Chapter 2 Installing the Drive in the
Installation Guide for instructions on connecting a
braking resistor.
Braking resistor
The Drive does not contain a
braking resistor; when
Warning
If a braking resistor is being used, set the following
parameter at FASt in order to prevent instability:
Macro Parameter
0 2 3 4
1 5 6 7 See the Commander Gp Advanced User Guide
For Macros 1 and 5, the Note at the beginning of
Enabling Macro 1 earlier in this chapter gave
instructions for changing the setting of this
parameter. When Macro 6 or 7 is enabled, the
setting is made automatically. See 0.15 Ramp mode
selector in Appendix D Menu 0 Parameters.
required, an external
braking resistor must be
used (see the Installation
Guide).
Depending on the setting of
parameter 0.15, failure to
connect a braking resistor
when one is required may
result in deceleration times
being extended or the Drive
tripping during braking
which would leave the
motor free to coast.
0.15 Ramp mode selector
If the required acceleration cannnot be achieved, it
may be necessary to increase the value of
0.06 Current limit.
Commander GP User Guide
Issue code: gpxu2
Getting Started 2-15
Page 26
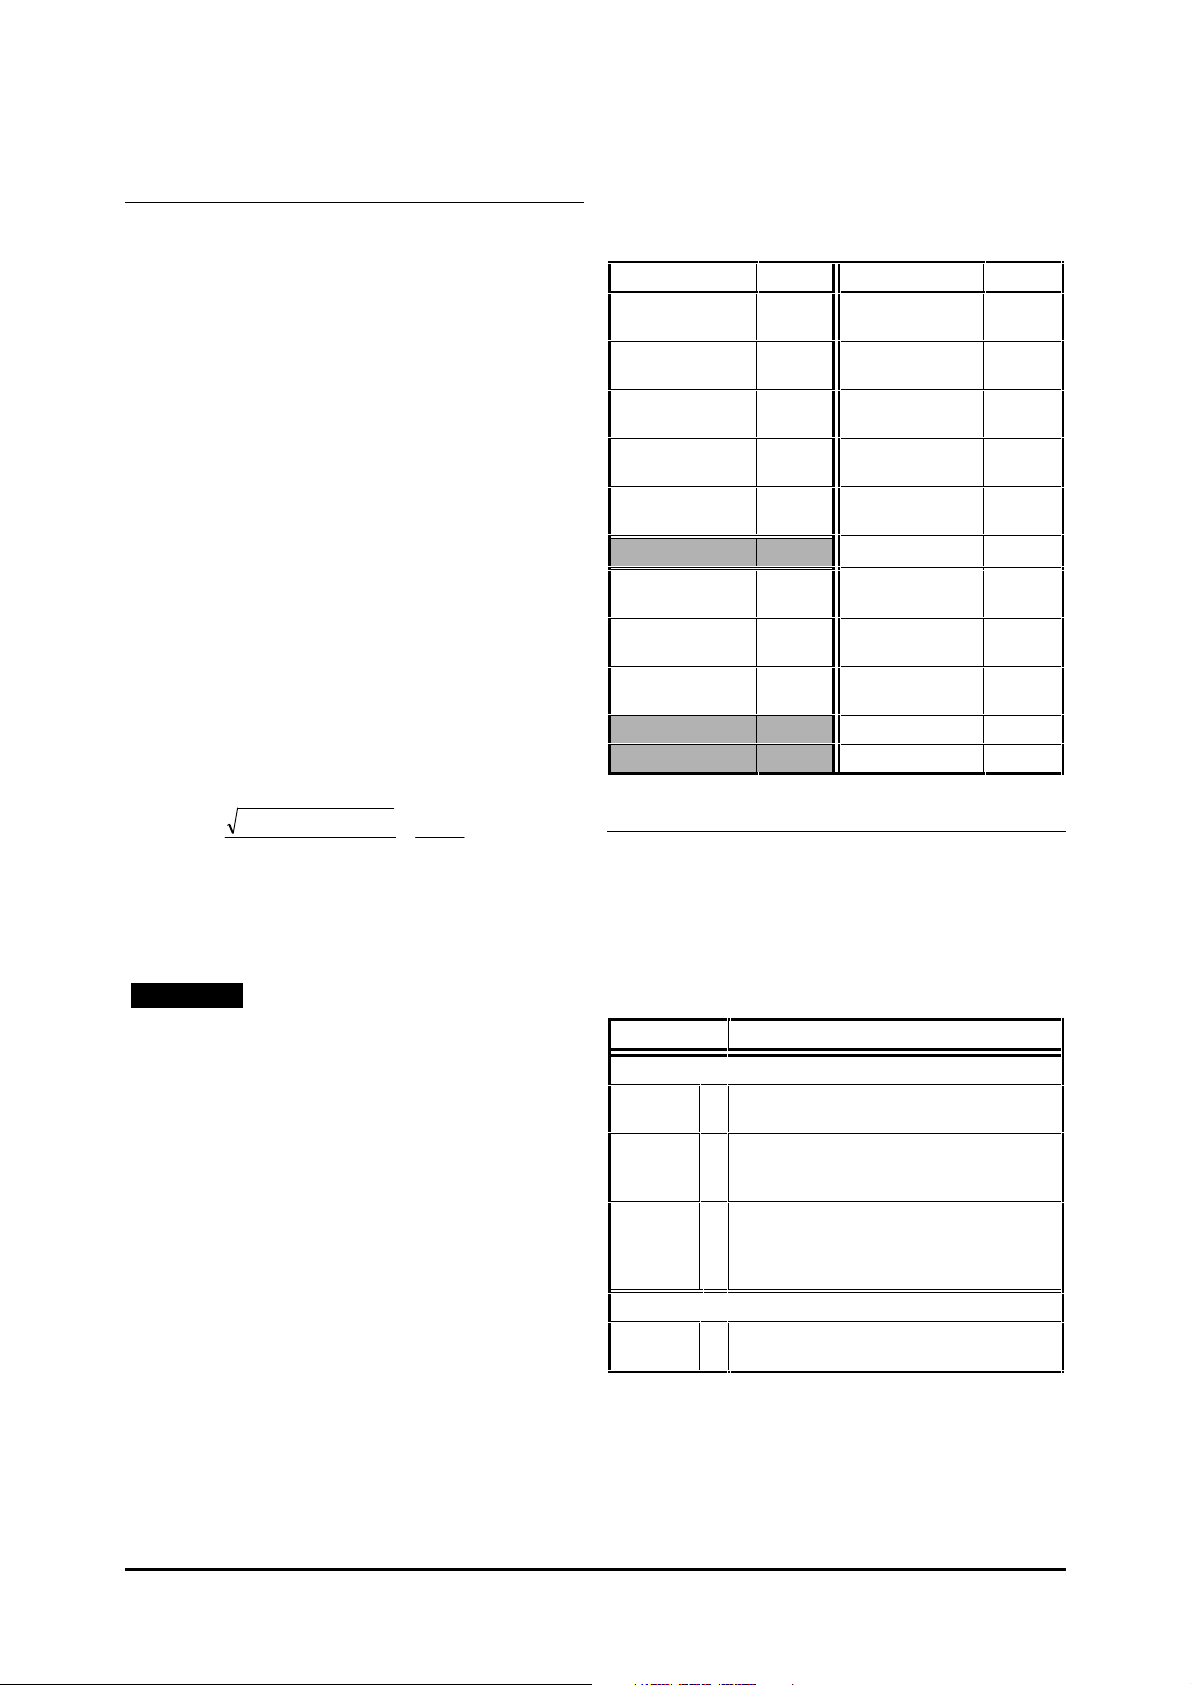
Torque-producing current limit
Model
GPD 3201
GPD 3401
GPD 3402
GPD 3202
GPD 3403
GPD 3203
GPD 3404
GPD 3405
GPD 3204
GPD 4401
GPD 4402
GPD 4403
GPD 4404
GPD 4405
The value of FLC is given in the following table.
Set parameter 0.06 Current limit at the required
percentage of rated motor torque (or rated active
torque-producing current).
The current limit is used to protect the motor and
Drive from excessive current and applies under
motoring and regenerating conditions. When the
Drive is operating in torque control, the current
limit limits the value of torque demand.
The total motor current comprises a magnetizing
current and an active (torque-producing) current.
Since the maximum torque produced by the motor
is proportional to the value of parameter 0.06
Current limit, this current limit is a torque-producing
current limit.
When 0.06 is set at its maximum value, the
maximum total motor current is as follows:
150% x FLC
Where FLC is the rated (full-load) current of the
Drive.
The maximum value of 0.06 is given by the
following (but cannot exceed 400 (%)):
Values of FLC
Model FLC (A)
GPD 1201
GPD 1401
GPD 1202
GPD 1402
GPD 1203
GPD 1403
GPD 1204
GPD 1404
GPD 1205
GPD 1405
GPD 2201
GPD 2401
GPD 2202
GPD 2402
GPD 2203
GPD 2403
25
12
16
2.1
2.8
3.8
5.6
9.5
FLC (A)
34
40
46
60
70
74
96
124
156
180
202
22
( . ) ( cos )
15 1
[. ]
MAX
==
−−−−
cos [ . ]
φφ
φφ
FLC
××××
046
100
(%)006
Where:
[0.46] = Value of Motor – rated current
cosφ is the power factor of the motor.
Note
The results from these equations may not
correspond exactly with the maximum
output current from the Drive, since the
Drive may round up the calculated figure.
Voltage-control modes
The default setting is as follows:
Macro 1: Fd
Macros 0, 2, 3, 4, 5, 6, 7: Ur_I
To change the voltage control mode, select the
required setting in parameter 0.07 Voltage mode
selector, as follows:
Setting Function
Vector modes
Ur_S
Ur_I
Ur
Fd
0 Motor stator resistance is measured each
time the Drive is started.
1 Motor stator resistance is measured at
power-up if the
closed and no other trip condition exists.
2 Motor stator resistance is not measured
(use this mode only after having used
Ur_S or Ur_I to measure the stator
resistance).
Fixed boost mode
3 Fixed voltage boost that can be manually
adjusted by parameter 0.08 Boost voltage.
EXTERNAL TRIPEXTERNAL TRIP contact is
2-16 Getting Started
The Vector modes give better performance at low
speed than the fixed-boost mode, but require the
stator resistance to be accurately measured by the
Drive.
Commander GP User Guide
Issue code: gpxu2
Page 27
Note
If parameter 0.39 Synchronize to a spinning
motor is to be set at 1, for reliable
operation of the Drive, set parameter 0.07
at Fd.
When Ur_I is selected, the
AC
Warning
motor might kick when the
supply is connected to the
Drive (with the
contact already closed).
EXTERNAL TRIP
Boost voltage
Use this procedure only when 0.07 Voltage mode
selector has been set at Fd.
Where actions apply to a particular control mode,
the following key is used:
K> Keypad mode
T> Terminal mode
1. Connect the load to the motor.
2. Close the EXTERNAL TRIP contact.
3. Ensure the frequency reference is zero.
4. K> Press
T> Close the RUN FORWARD or RUN
REVERSE contact.
Increase the frequency reference to a value
slightly above zero. If the motor shaft does
not rotate, increase the value of parameter
0.08 Boost voltage sufficiently to cause the
shaft to rotate.
Default value: 3%
Range: 0 ~ 25%
5. If the motor is noisy and becomes unnecessarily
heated, reduce the value of 0.08.
6. Stop the Drive.
Save the new parameter-value.
Voltage/frequency characteristic
If the motor is to drive a pump or fan where the load
can vary, set parameter 0.09 Dynamic V/f select at 1.
This selects an automatic voltage/frequency
characteristic which reduces power consumption
and acoustic noise in the motor when lightly loaded.
For an explanation of the effects of the
voltage/frequency characteristic, see parameter 0.09
Dynamic V/f select in Appendix D Menu 0 Parameters.
Commander GP User Guide
Issue code: gpxu2
Getting Started 2-17
Page 28
2-18 Getting Started
Commander GP User Guide
Issue code: gpxu2
Page 29
3 Setting Up the Drive
(Macro Configurations)
Do not change parameter
values without careful
Warning
consideration; wrong values
may cause damage or a safety
hazard.
3.2 Enabling a different
macro configuration
Do not attempt to enable any
macro configuration when the
Drive is running.
Warning
Note
Notes
Keep a note of changes
When changing the values of parameters,
make a note of the new values in case they
need to be entered again.
Saving the changes
For new parameter-values to apply after
AC supply to the Drive is interrupted,
the
new values must be saved. Refer to
Saving new parameter-values in Appendix A
Programming Instructions.
3.1 How to use this chapter
When setting up the Drive for the first time, you
must first have followed Chapter 2 Getting Started;
Macro 1 Easy mode will then be enabled. Whether
you keep Macro 1 or enable a different macro
configuration, the settings you made in Chapter 2
will remain unchanged. During the course of setting
up the Drive, you may need to change some of these
settings. If so, refer again to Chapter 2.
It is recommended that you follow the instructions
in this chapter in the order that they appear. You
will be led through the following:
• • Enabling the required macro
configuration (if a macro other than
Macro 1 is required)
• • Changing the signal connections
accordingly
• • Adjusting parameters that are
specific to the macro configuration
• • A list of subsidiary functions that
can be set up
Only one macro configuration can be
enabled at a time.
Enabling a different macro
configuration after getting started
with Macro 1
If Macro 1 is to remain enabled, ignore this section
and go to Macro 1 later in this chapter.
1. To enable a different macro configuration, set
parameter 0.00 as follows:
Macro Function Setting
2 Motorized potentiometer
(frequency control by up and
down contacts)
3 Four preset frequencies
(selected by digital control
signals)
4 Torque control 2004
5 PID (set-point) control 2005
6 Axis-limit control 2006
7 Brake control 2007
0 General purpose
(USA default configuration)
General purpose
(EUR default configuration)
Note
The values of the fixed parameters are not
changed when any one of these macro
configurations is enabled.
When Macro 0 is enabled, the
functions of parameters
Caution
0.27 to 0.29 differ between
the EUR and USA default
configurations.
2002
2003
2009
2010
Commander GP User Guide
Issue code: gpxu2
2. Reset the Drive.
3. Go to the relevant section in this chapter for
the macro configuration that has been enabled.
Setting Up the Drive 3-1
Page 30
Enabling a different macro
configuration after using Macros 2 to 7
If any one of the macros from 2 to 7 has been
enabled (after the instructions in this chapter have
previously been followed), proceed as follows...
1. Go to Initial setting up in Chapter 2 Getting
Started. Start proceeding through that section
by referring to Restoring the Drive to a default
configuration.
2. Follow the remainder of Initial setting up.
3. Return to this chapter and follow Enabling a
different macro configurationafter getting started
with Macro 1 earlier in this chapter.
3.3 Macro 0
General purpose
(
default configuration
Features
Specific features
Macro 0 places the Drive in a default configuration
for general-purpose use.
When a UD50 small option module is fitted in the
Drive, the following additional functions become
automatically available for Macro 0 only:
• Volt-free relay contact which closes when
the Drive is AT OR BELOW MINIMUM SPEED
• Volt-free relay contact which closes when
the Drive is AT SPEED
• DRIVE RUNNING digital output
• MOTOR CURRENT OVERLOAD ALARM
digital output
• (EXCESSIVE) HEATSINK TEMPERATURE
ALARM digital output
• MOTOR CURRENT MAGNITUDE
analog output
• Frequency offset can be selected and
applied
• Operation in torque mode can be selected
• A bipolar or unipolar frequency reference
can be applied
To change the functions of the UD50 or to enable
the UD50 to be used with other macro
configurations, see the Commander Gp Advanced User
Guide. With Drive software versions V03.01.05, a
UD50 cannot be used with any of the other macro
configurations.
)
Standard features
• Macro 0 operates in Terminal or Keypad
mode
• In Terminal mode, digital control by
RUN FORWARD, RUN REVERSE and
JOG SELECT contacts
• Local and remote analog frequency inputs,
or setting of frequency by use of the keypad
• Keypad control of speed can be
uni-directional or bi-directional
• Selection of analog input modes
• Adjustable Jog/Preset frequency
• Adjustment of minimum and maximum
frequencies
• Adjustment of acceleration and deceleration
ramps
• S-ramp
• Skip frequencies
• Selection of stopping modes
• Selection of braking mode
• Motor thermistor input
• Negative logic for the digital inputs
(EUR> positive logic can be selected)
• EUR> Adjustment of current-loop PI gains
• USA> Indication of frequency demand
• USA> Digital control by three-wire
momentary contacts can be selected
• SPEED and TORQUE analog outputs
• AT SPEED digital output
• External trip digital input
• Drive RESET digital input
3-2 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 31
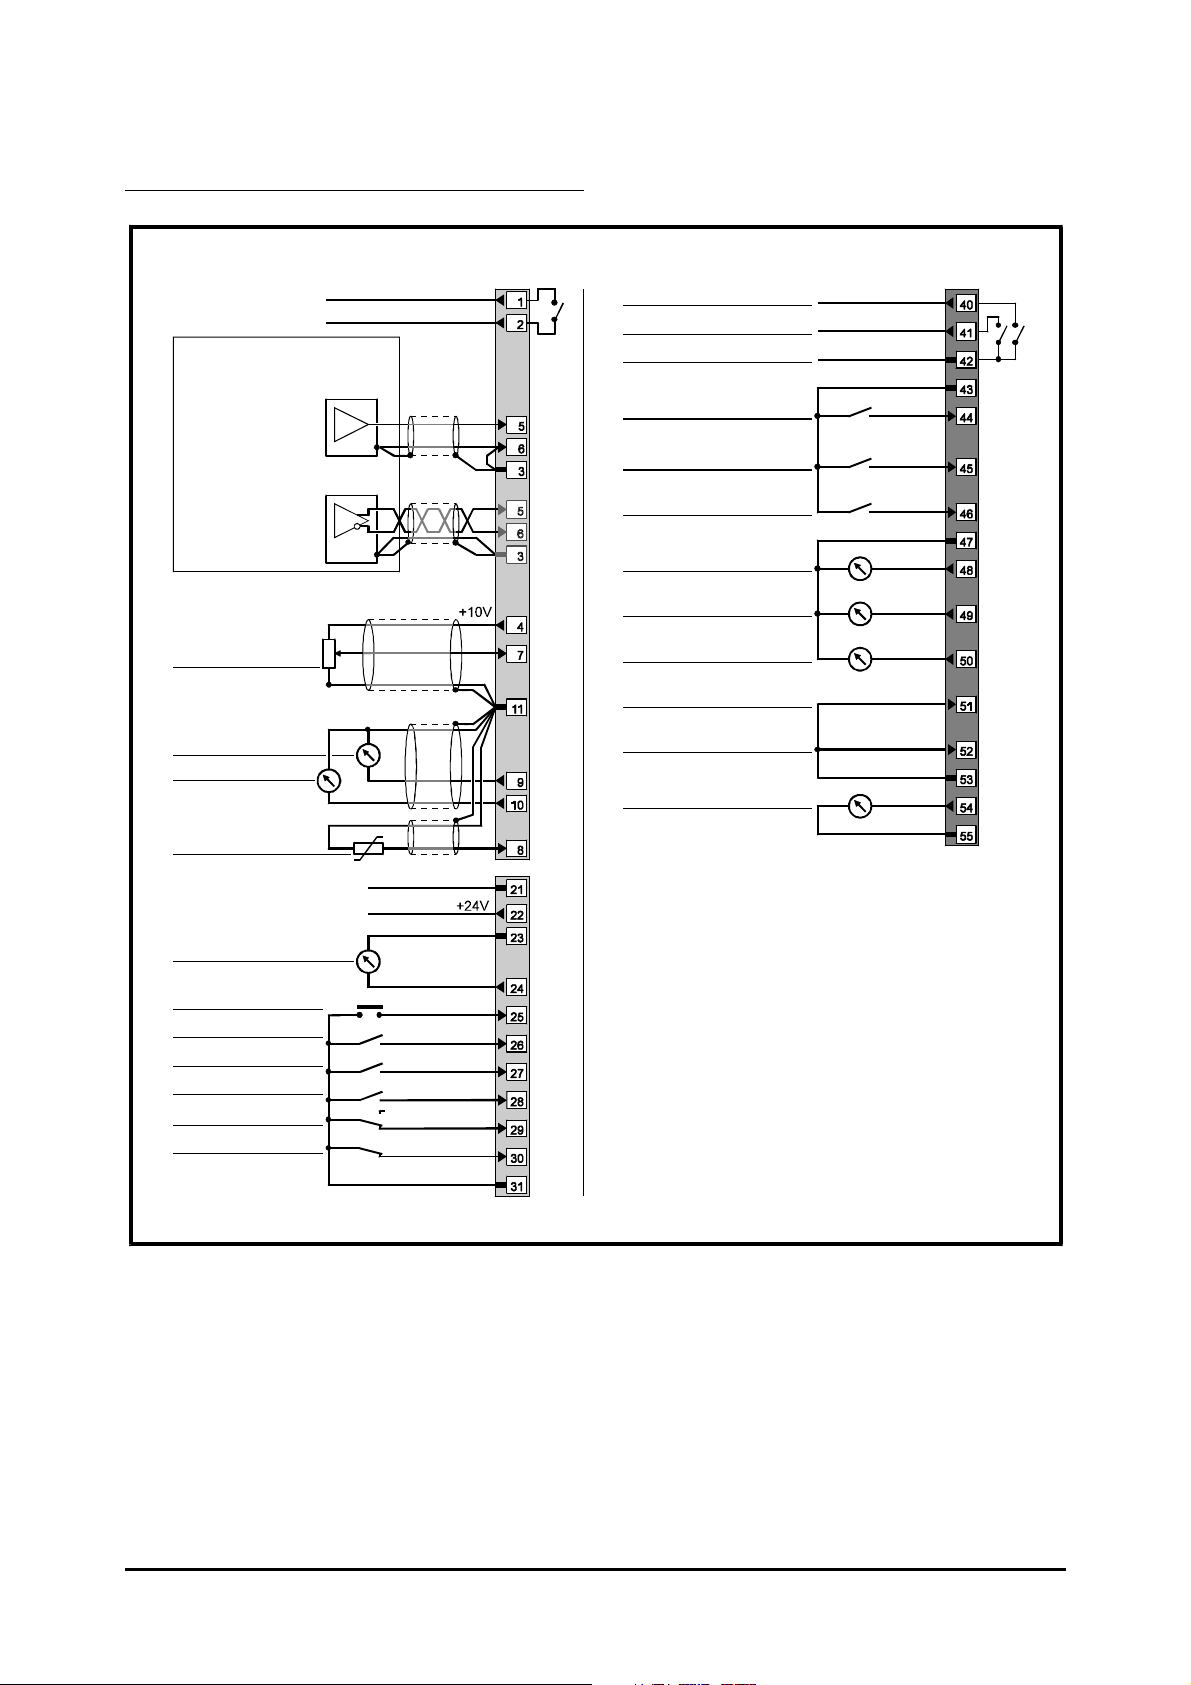
Signal connections for Macro 0
Status relay
Drive healthy
Analog frequency reference 1
(remote)
Connections for
single-ended input
Connections for
differential input signal
Analog frequency
reference 2
(local)
SPEED
TORQUE
signal
0V common
0V common
0V common
Signal
connector
AT OR BELOW
MINIMUM SPEED
AT SPEED
(Relay common)
FREQ. OFFSET
SELECT
TORQUE MODE
SELECT
BIPOLAR REFERENCE
SELECT
DRIVE RUNNING
MOTOR CURRENT
OVERLOAD ALARM
HEATSINK
TEMPERATURE ALARM
Frequency offset
0 ~ ±10V
Torque reference
0 ~ ±10V
Motor current magnitude
0 ~ ±10V
0V common
0V common
0V common
UD50
connector
Motor thermistor
0V common
AT SPEED
RESET
JOG SELECT
RUN FORWARD
RUN REVERSE
LOCAL / REMOTE
External trip
0V common
REMOTE
LOCAL
0V common
Figure 3–1 Control signal and thermistor connections for Macro 0 (showing optional connections
to a UD50 small option module)
For electrical specifications, refer to Appendix C
Signal Connections.
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-3
Page 32
RESET
EXTERNAL TRIP
LOCAL /
REMOTE
29
BIPOLAR
SELECT
46
JOG
SELECT
26 27 2825 30
RUN
FORWARD
RUN
REVERSE
Reference selection
Frequency reference 1
(remote)
5
6
Analog input 2
mode
selector
7
Frequency reference 2
(local)
FREQUENCY OFFSET SELECT
0.25
Preset references
(use Macro 3)
Analog input 1
mode
selector
0.24
0.35
Keypad
reference
Reference
selector
0.05
44
51
FREQUENCY OFFSET
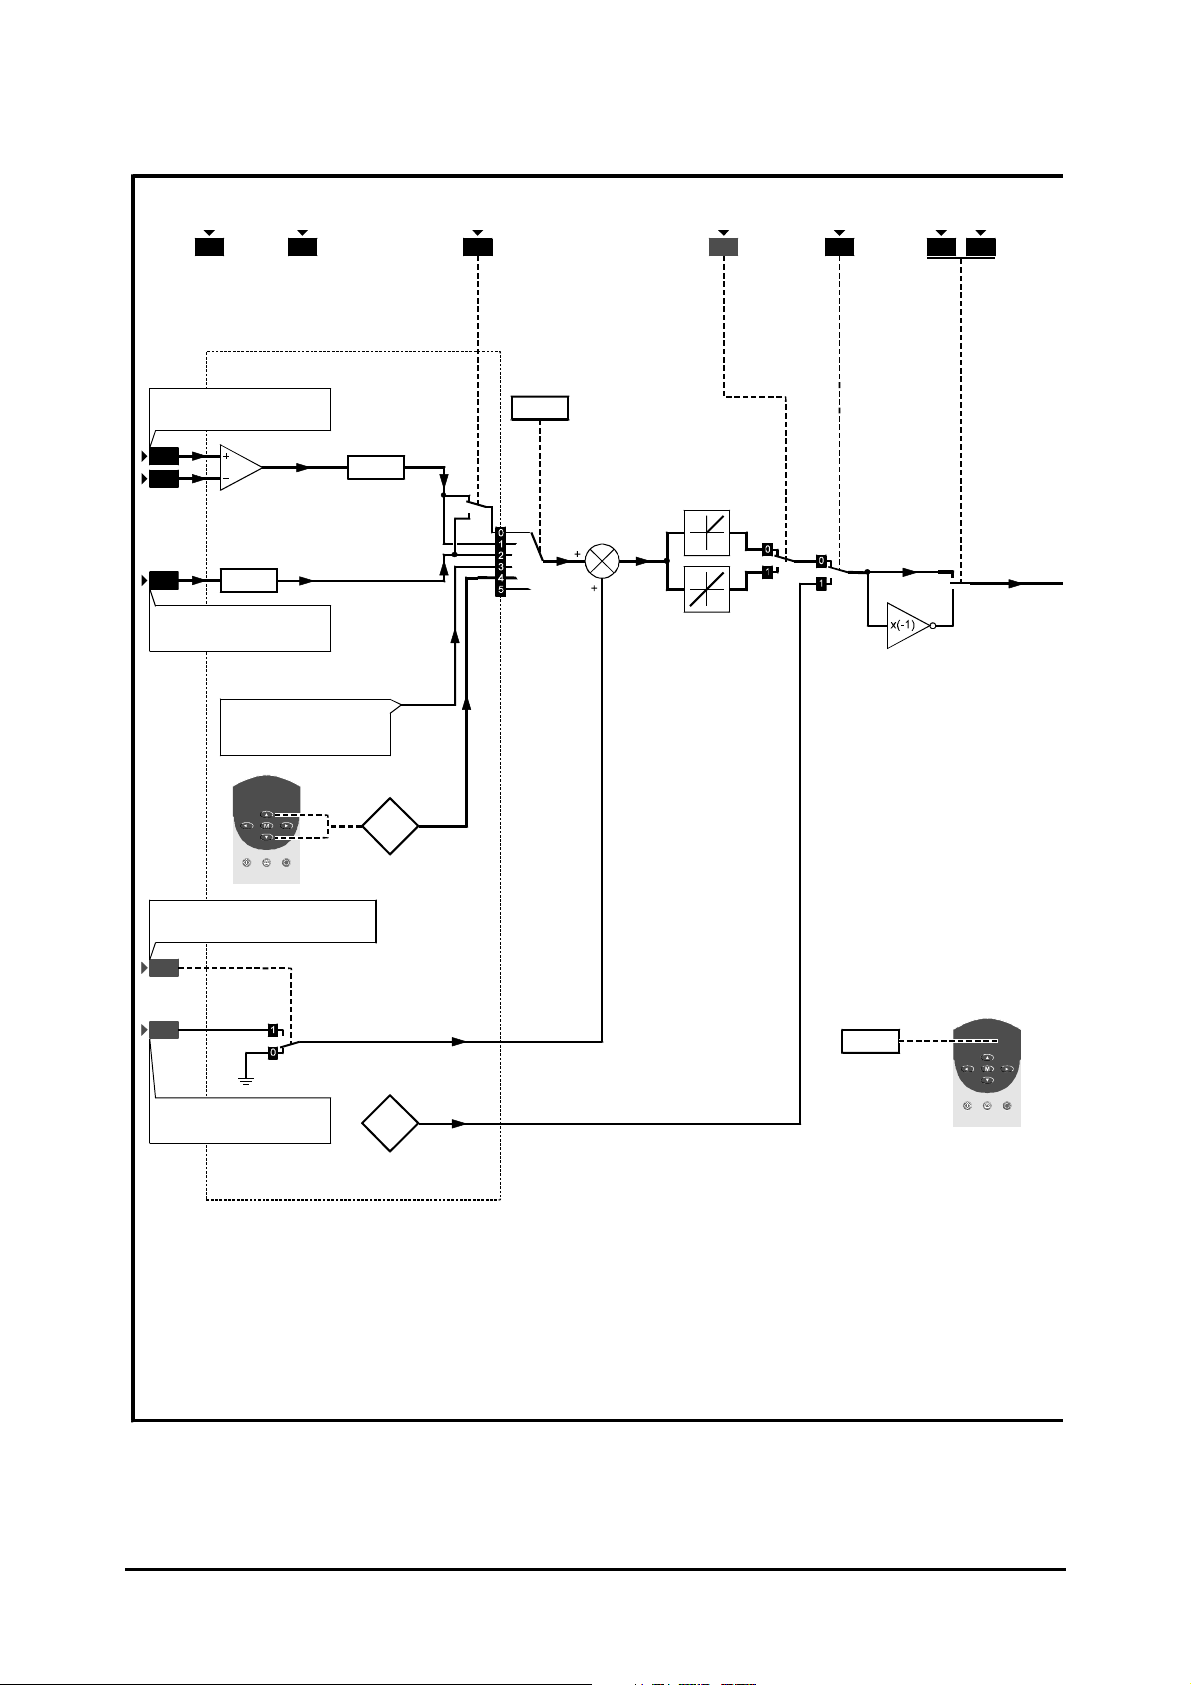
The parameters are shown at their default settings.
The logic diagram is valid when all parameters are
at their default settings but may not be valid when
certain parameters are adjusted.
0.14
Jog
reference
Figure 3–2 Programmable software for Macro 0
3-4 Setting Up the Drive
0.38
Initial
parameter
displayed
Commander GP User Guide
Issue code: gpxu2
Page 33
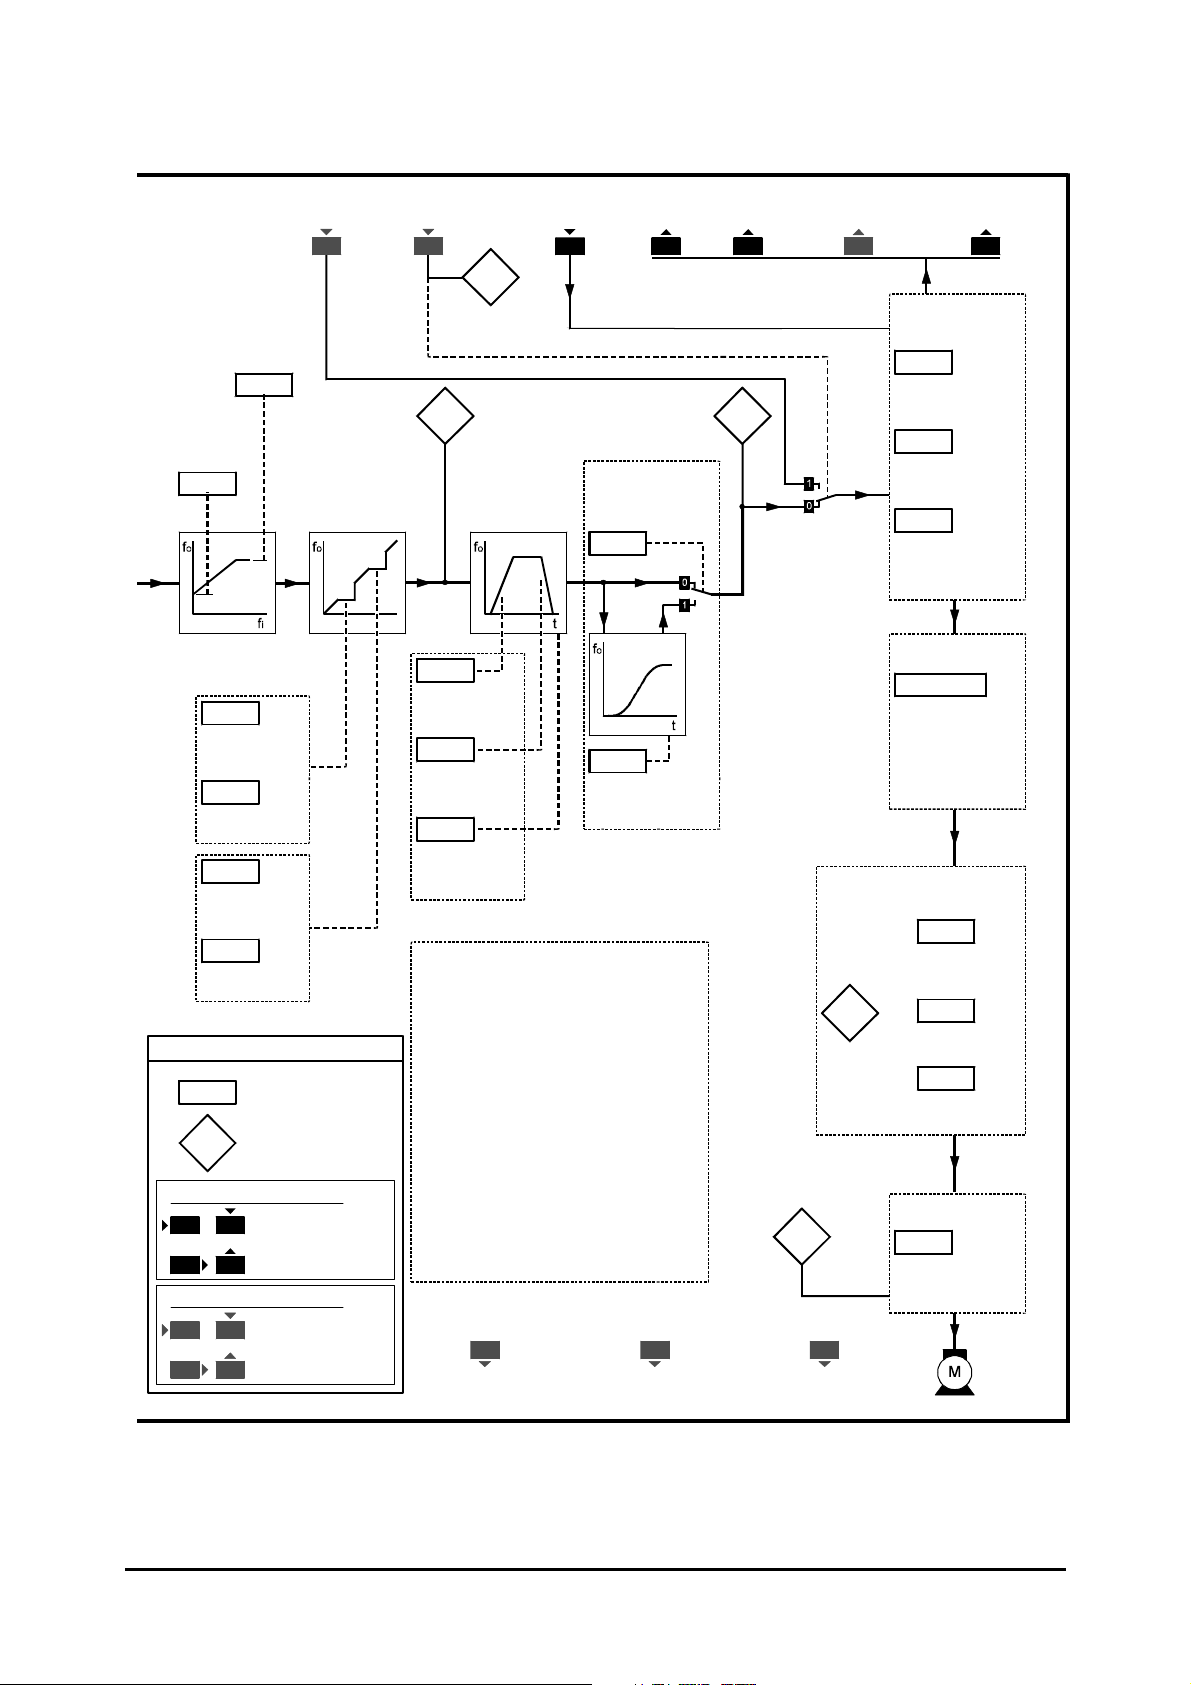
REFERENCE
Maximum
frequency
0.02
Minimum
frequency
0.01
0.20
Skip frequency
1
0.21
Skip band 1
0.22
Skip frequency
2
0.23
Skip band 2
Read-write (RW)
0.XX
parameter
Read-only (RO)
0.XX
parameter
Signal connector
X X
X X
UD50
X X
X X
Input terminals
Output terminals
Input terminals
Output terminals
TORQUE
Key
TORQUE MODE
52
Skip
frequencies
SELECT
45
Torque mode
select
0.11 0.12
0.03
Acceleration
rate
0.04
Deceleration
rate
0.15
Ramp mode
selector
Other parameters
0.31 Macro number
0.32 Serial comms. mode
0.33 Drive rated current
0.34 User security code
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.40 Autotune
0.48 Drive software build number
0.49 Security status
0.50 Software version number
DRIVE RUNNING
THERMISTOR
0.17
indicator
Pre-ramp
reference
Ramps
48
8
SPEED TORQUE
9 10 24
Post-ramp
reference
S-ramp
S-ramp
enable
0.18
0.19
S-ramp
da/dt limit
49
MOTOR CURRENT
OVERLOAD ALARM
MOTOR CURRENT
MAGNITUDE
54
Motor-voltage control
0.10
Estimated
motor
speed
Motor
active-current
0.13
49
HEATSINK
TEMPERATURE ALARM
AT SPEED
Motor control
0.06
Current
limit
0.16
Stop mode
selector
0.39
Synchronize
to a spinning
motor
Motor parameters
0.42 ~ 0.47
No. of poles
Power factor
Rated voltage
Rated speed
Rated current
Rated frequency
0.07
Voltage mode
selector
0.08
Boost voltage
0.09
Dynamic V/f
select
Power stage
0.41
PWM switching
frequency
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-5
Page 34
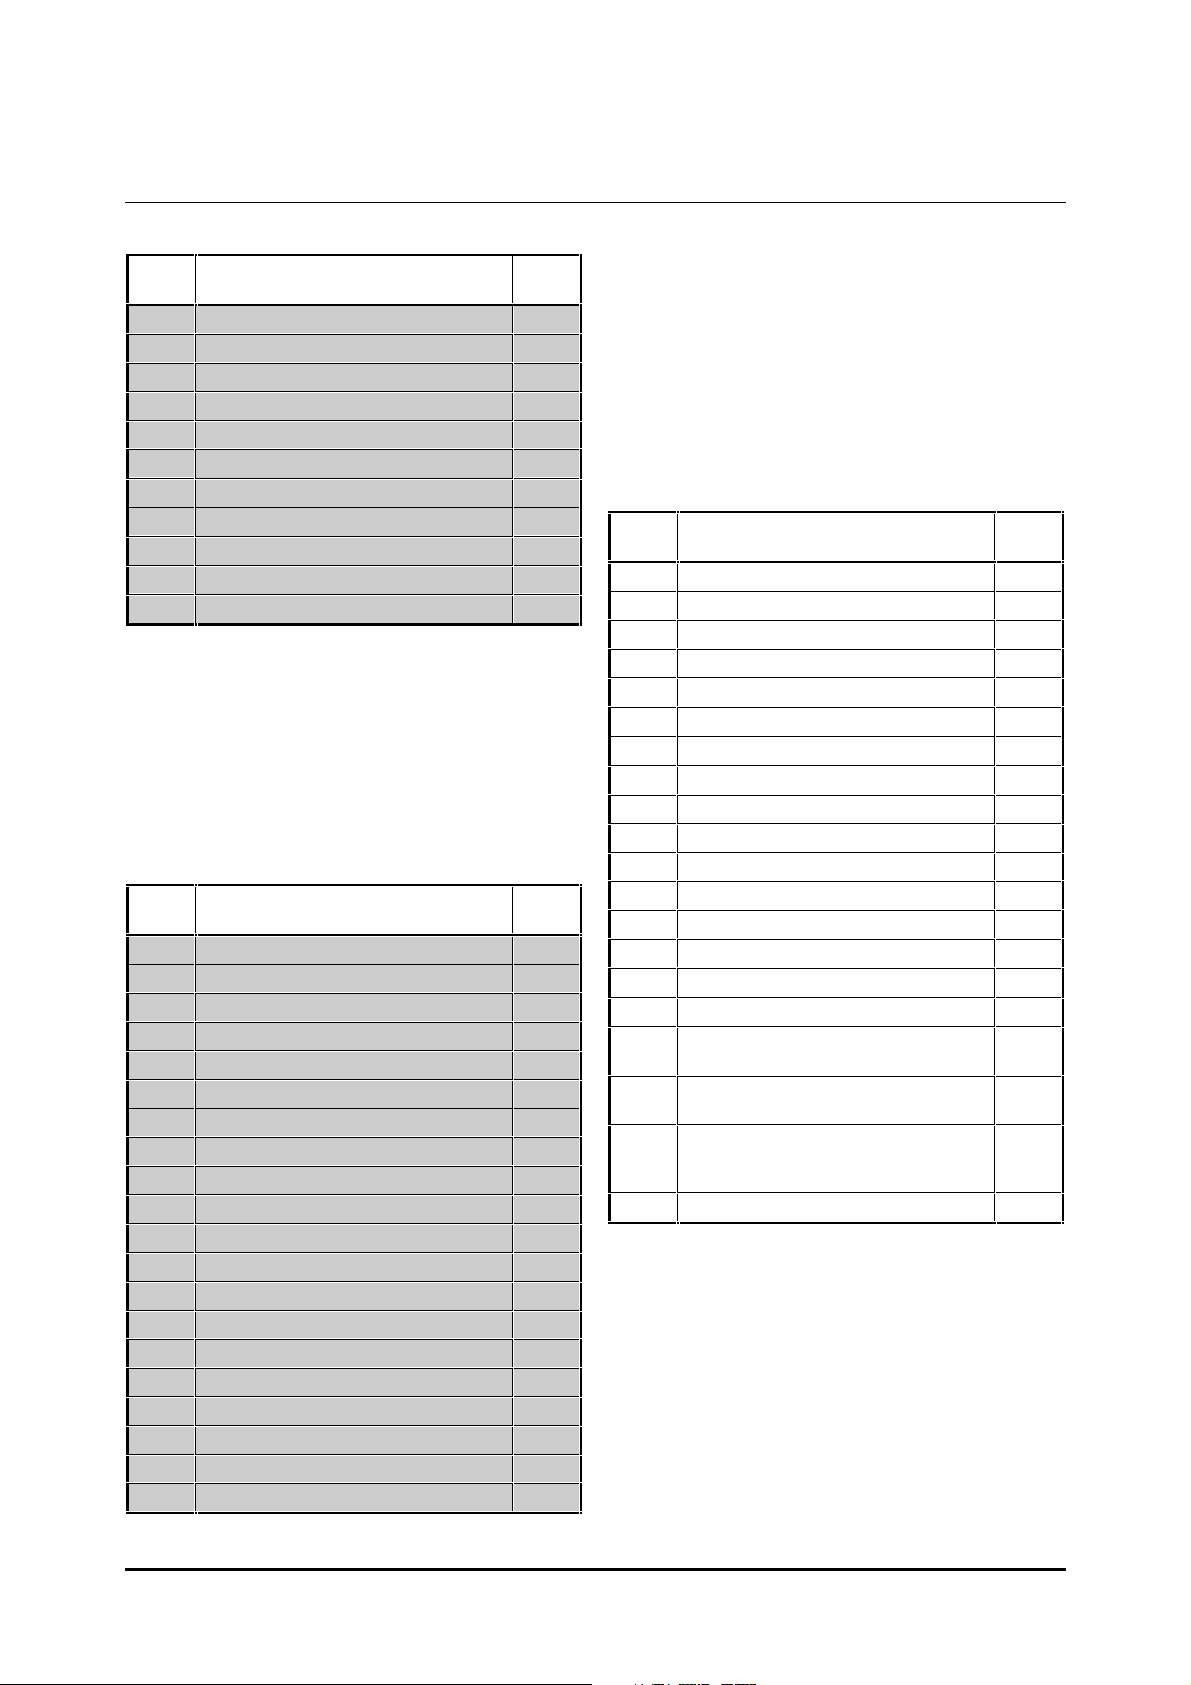
List of parameters specific to Macro 0
Pr Function User
value
0.00 Configuration and saving
0.01 Minimum frequency
0.02 Maximum frequency
0.03 Acceleration rate
0.04 Deceleration rate
0.05 Reference selector
0.06 Current limit
0.07 Voltage mode selector
0.08 Boost voltage
0.09 Dynamic V/f select
0.10 Estimated motor speed [M]
Pr Function User
value
0.31 Macro number [M]
0.32 Serial comms. mode
0.33 Drive rated current (FLC) [M]
0.34 User security code [M]
0.35 Keypad reference [M]
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.38 Initial parameter displayed
0.39 Synchronize to a spinning motor
0.40 Autotune
0.41 PWM switching frequency selector
0.42 Motor – number of poles
0.43 Motor – power factor
0.44 Motor – rated voltage
0.45 Motor – rated speed
0.46 Motor – rated current
0.47 Motor – rated frequency
0.48 Drive software build number [M]
0.49 Security status [M]
0.50 Drive software version [M]
[M] indicates the parameter is for monitoring only
For descriptions of these parameters,
see Appendix D Menu 0 Parameters.
Pr Function User
value
0.11 Pre-ramp reference [M]
0.12 Post-ramp reference [M]
0.13 Motor active-current [M]
0.14 Jog reference
0.15 Ramp mode selector
0.16 Stop mode selector
0.17 Torque mode selector
0.18 S-ramp enable
0.19 S-ramp da/dt limit
0.20 Skip frequency 1
0.21 Skip band 1
0.22 Skip frequency 2
0.23 Skip band 2
0.24 Analog input 1 mode selector
0.25 Analog input 2 mode selector
0.26 Analog input 2 destination selector
0.27 EUR> Positive logic select
USA> Sequencing mode selector
0.28 EUR> Current-loop proportional gain
USA> Frequency demand
0.29 EUR> Current-loop integral gain
USA> Terminal-29
destination parameter
0.30 FWD/REV key enable
3-6 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 35
Setting up and using Macro 0
Range
0 ~ 400.0
Jog/Preset frequency
The following may require attention in addition to
the settings made in Chapter 2.
UD50 small option module
When any of the additional functions listed above in
Specific features are required, refer to the UD50 User
Guide for installing a UD50 module, as well as for the
specifications of the terminals.
Reference selection
Use 0.05 Reference selector to select the required
frequency source, as follows:
0.05 Source Terminal(s)
0 Analog input 1 or 2 which can be
selected using the LOCAL/REMOTE
contact
1 Analog input 1 5, 6
2 Analog input 2 7
3 Preset frequencies (Do not use this
setting, use Macro 3 instead)
4 Keypad control
5 (Do not use)
5 and 6, or 7
Analog input modes
The analog inputs can be configured for the
following input signals:
0 ~ 20mA, 4 ~ 20mA or 0 ~ 10V
Refer to the following parameters in Appendix D
Menu 0 Parameters for selecting the required mode:
Analog
input
1 5, 6
27
Terminal(s) Parameter
0.24
Analog input 1 mode selector
0.25
Analog input 2 mode selector
Forward and reverse direction
in Keypad mode
The jog function can be used for low-speed jogging
or as a preset frequency at any value up to the
maximum.
If jog or a preset frequency is required, ensure the
Drive is in Terminal mode and set 0.14 Jog reference
at the required value, as follows:
Default
value
1.5
Unit
Hz
To use jog or preset frequency, close the JOG
SELECT contact (terminal 26) before closing the
RUN FORWARD contact (terminal 27) or RUN
REVERSE contact (terminal 28).
EUR> Selecting positive logic
Ensure the logic sense is
correct for the control circuit
to be used. Incorrect logic
Caution
sense could cause the motor to
be started unexpectedly.
By default, the digital inputs operate in negative
logic. For operation in positive logic, set
0.27 Positive logic select at 1.
USA> Digital control by three-wire
momentary contacts
1. Set 0.05 Reference selector at 0, 1 or 2.
2. Set 0.27 Sequencing mode selector at 0.
3. Set 0.29 Terminal-29 destination selector at 6.34
to change the function of terminal 29 to
RUN PERMIT / STOP.
Signal connector
JOG
RUN
REVERSE SELECT
STOP
The Drive is supplied with the (FWD/REV) key
disabled to ensure the Drive is run only in the
forward direction. To enable this key, set 0.30
FWD/REV enable at 1.
Commander GP User Guide
Issue code: gpxu2
0V common
Figure 3–3 Connections for control by 3-wire
momentary contacts
(see Figure 3–1 for
other connections)
Setting Up the Drive 3-7
Page 36
Stopping and braking modes
Refer to the following parameters in Appendix D
Menu 0 Parameters:
Parameter Setting Function
0.150.15
Ramp mode selector
0.160.16
Stop mode selector
Stnd.Ct
rP
(Standard controlled)
Deceleration time is
extended if the
voltage reaches its
maximum permissible
value during braking.
Ramp to stop then the
Drive is disabled
DC-bus
3-8 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 37
3.4 Macro 1
Easy mode
Features
Specific features
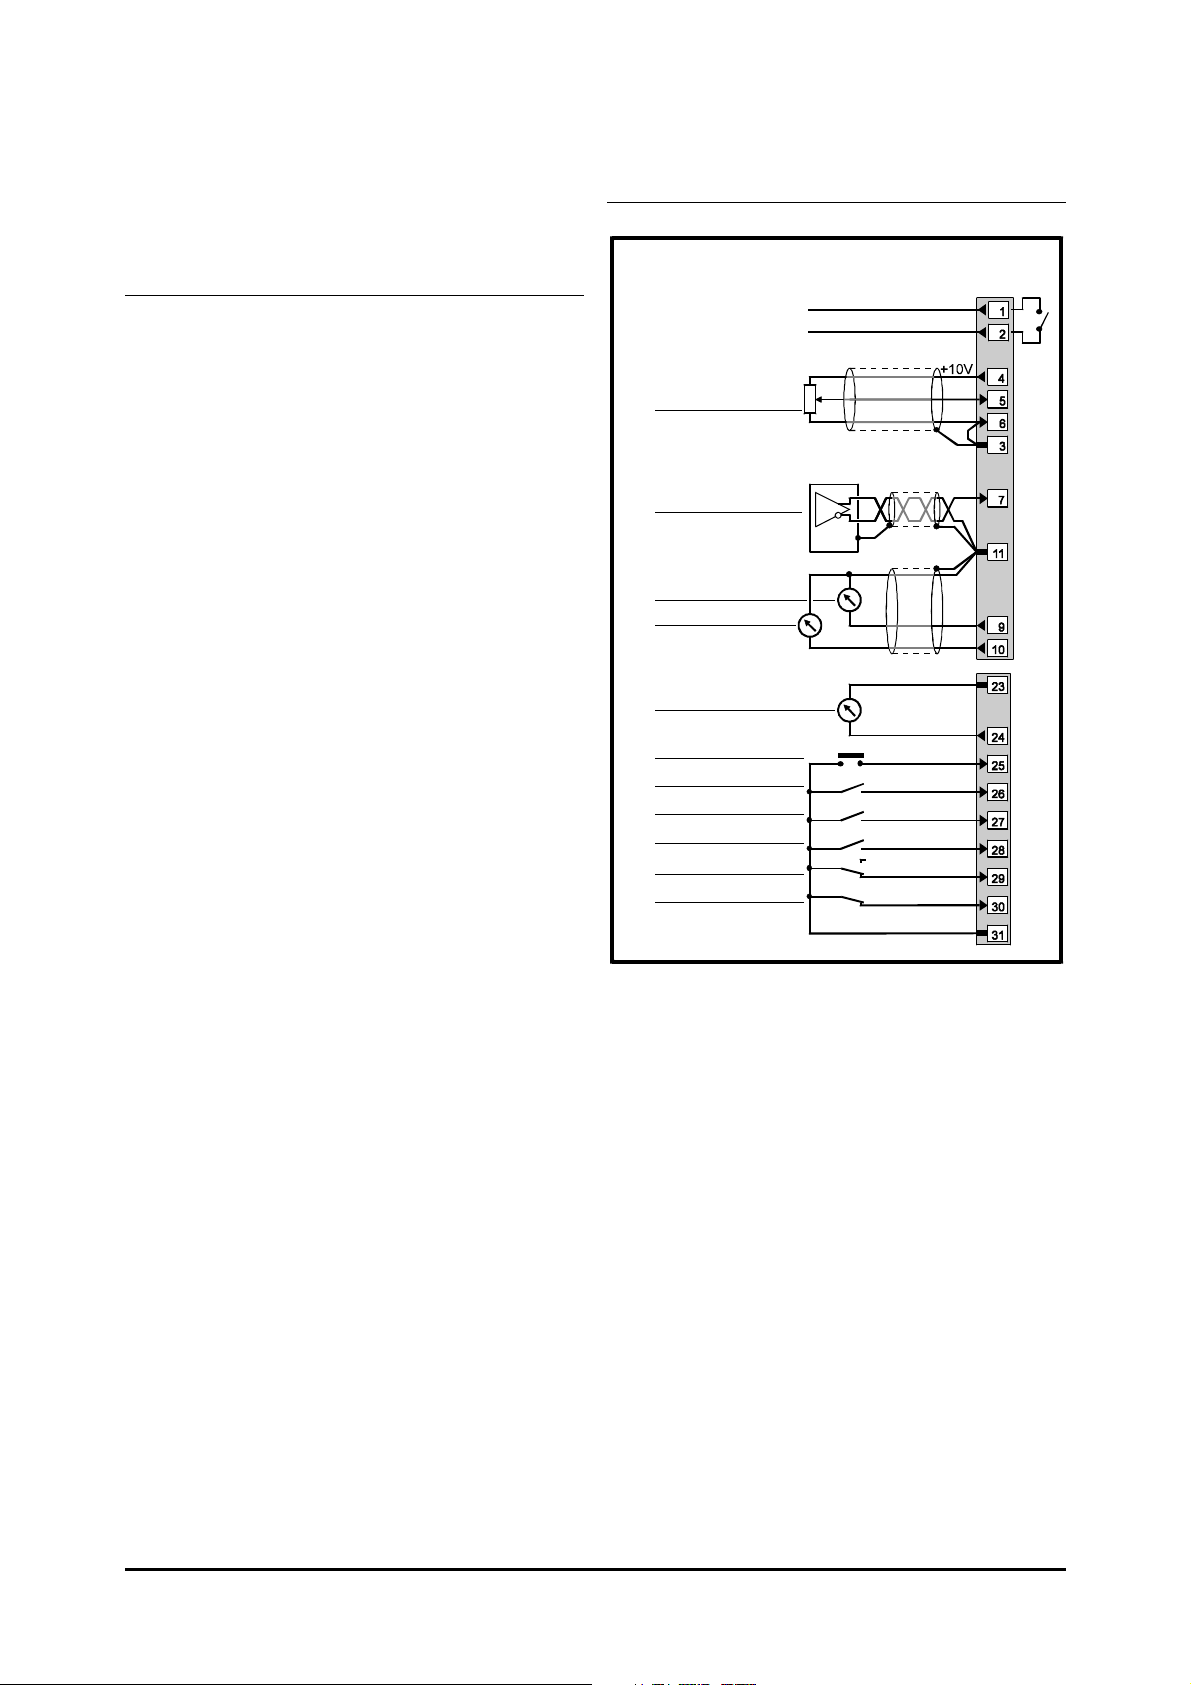
Signal connections for Macro 1
connector
Status relay
Drive healthy
Signal
Easy mode gives the simplest operation of the Drive
for basic applications.
Standard features
• Macro 1 operates in Terminal or Keypad
mode
• In Terminal mode, digital control by
RUN FORWARD, RUN REVERSE and
JOG SELECT contacts
• Local and remote analog frequency inputs,
or setting of frequency by use of the keypad
• Keypad control of frequency is
uni-directional only
• Fixed analog input modes
• Fixed jog frequency
• Adjustment of minimum and maximum
frequencies
• Adjustment of acceleration and deceleration
ramps
• Negative logic for the digital inputs
• SPEED and TORQUE analog outputs
• AT SPEED digital output
• External trip digital input
• Drive RESET digital input
Analog frequency
reference 1
(remote) 0 ~ 10V
Analog frequency
reference 2
(local) 4 ~ 20mA
SPEED
TORQUE
AT SPEED
RESET
JOG SELECT
RUN FORWARD
RUN REVERSE
LOCAL / REMOTE
External trip
0V common
0V common
0V common
REMOTE
LOCAL
0V common
Figure 3–4 Control signal connections
for Macro 1
Commander GP User Guide
Issue code: gpxu2
For electrical specifications, refer to Appendix C
Signal Connections.
Setting Up the Drive 3-9
Page 38
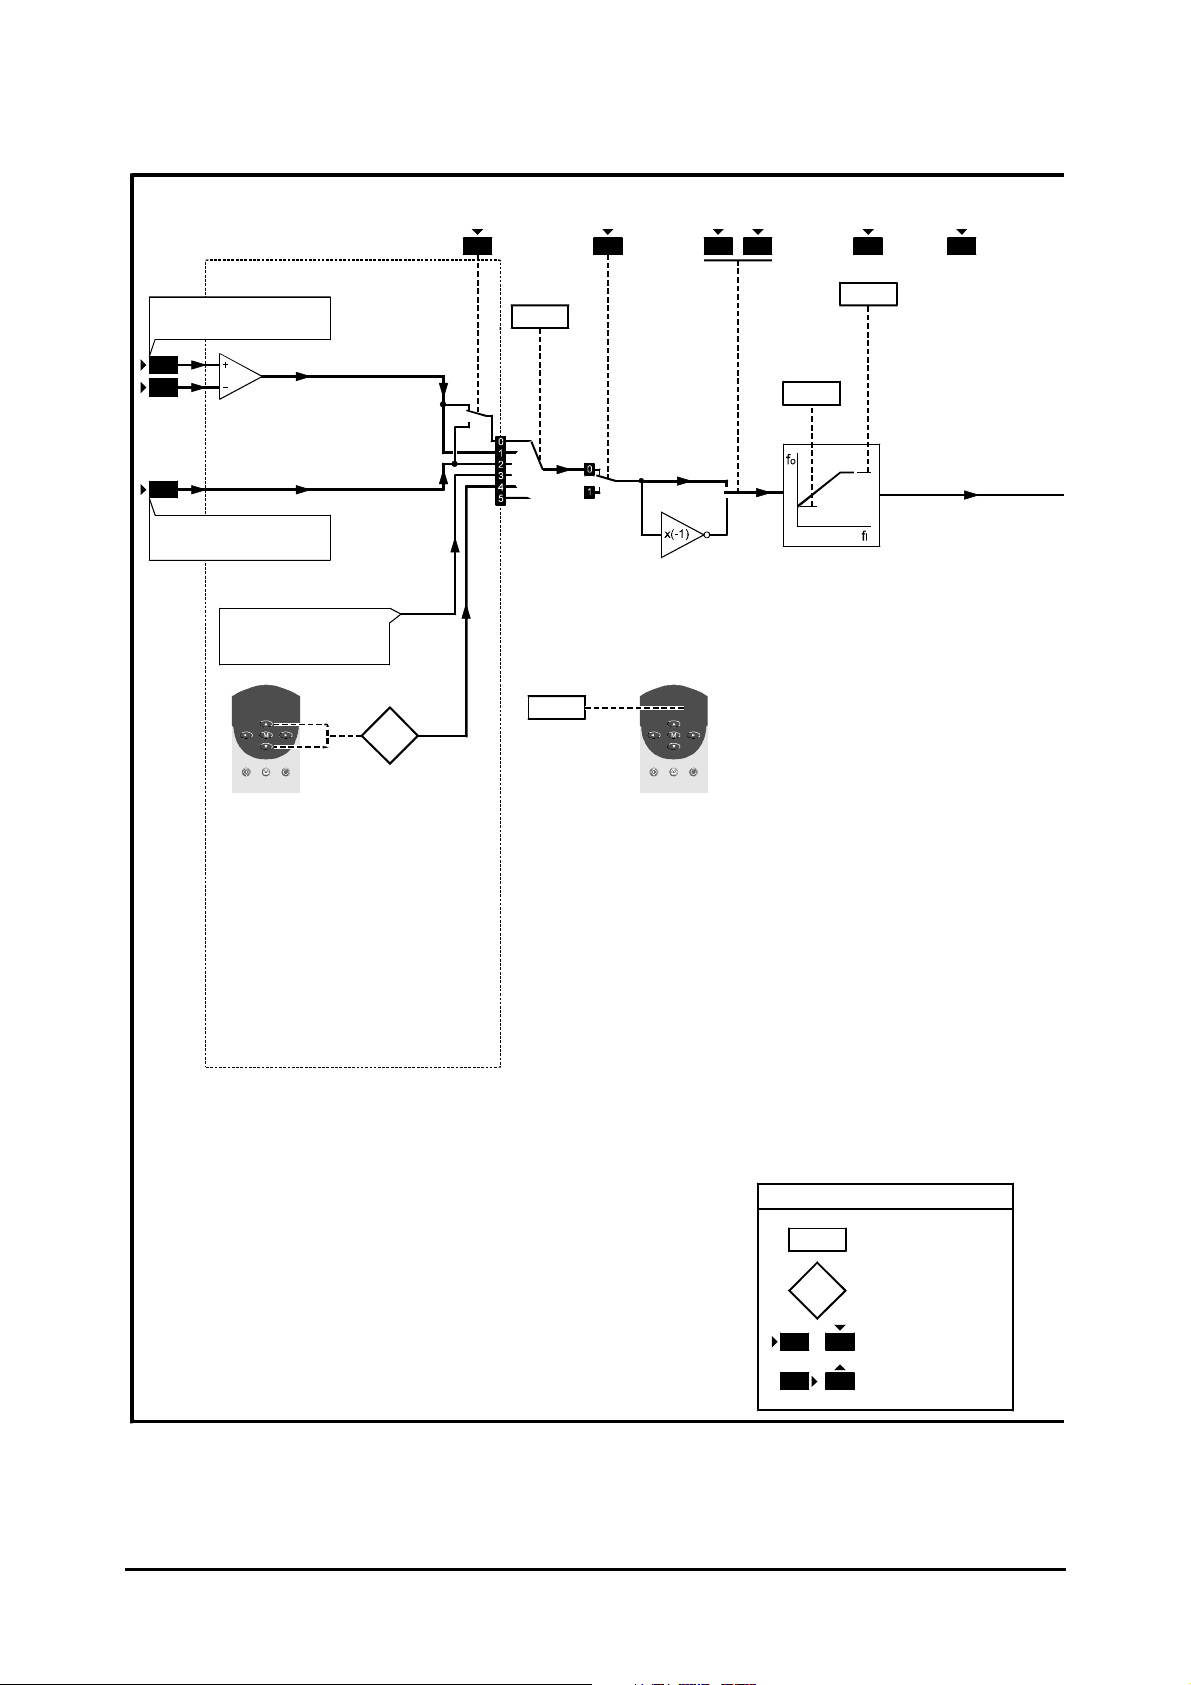
Reference selection
Frequency reference 1
(remote)
5
6
7
Frequency reference 2
(local)
Preset references
(use Macro 3)
0.35
Keypad
reference
LOCAL /
REMOTE
29
Reference
selector
0.05
0.38
Initial
parameter
displayed
JOG
SELECT
26 27 28
FORWARD
RUN
RUN
REVERSE
Minimum
frequency
0.01
RESET
25 30
0.02
EXTERNAL TRIP
Maximum
frequency
The parameters are shown at their default settings.
The logic diagram is valid when
at their default settings but may not be valid when
certain parameters are adjusted.
all
parameters are
Figure 3–5 Programmable software for Macro 1
3-10 Setting Up the Drive
0.XX
0.XX
X X
X X
Key
Read-write (RW)
parameter
Read-only (RO)
parameter
Input terminals
Output terminals
Commander GP User Guide
Issue code: gpxu2
Page 39
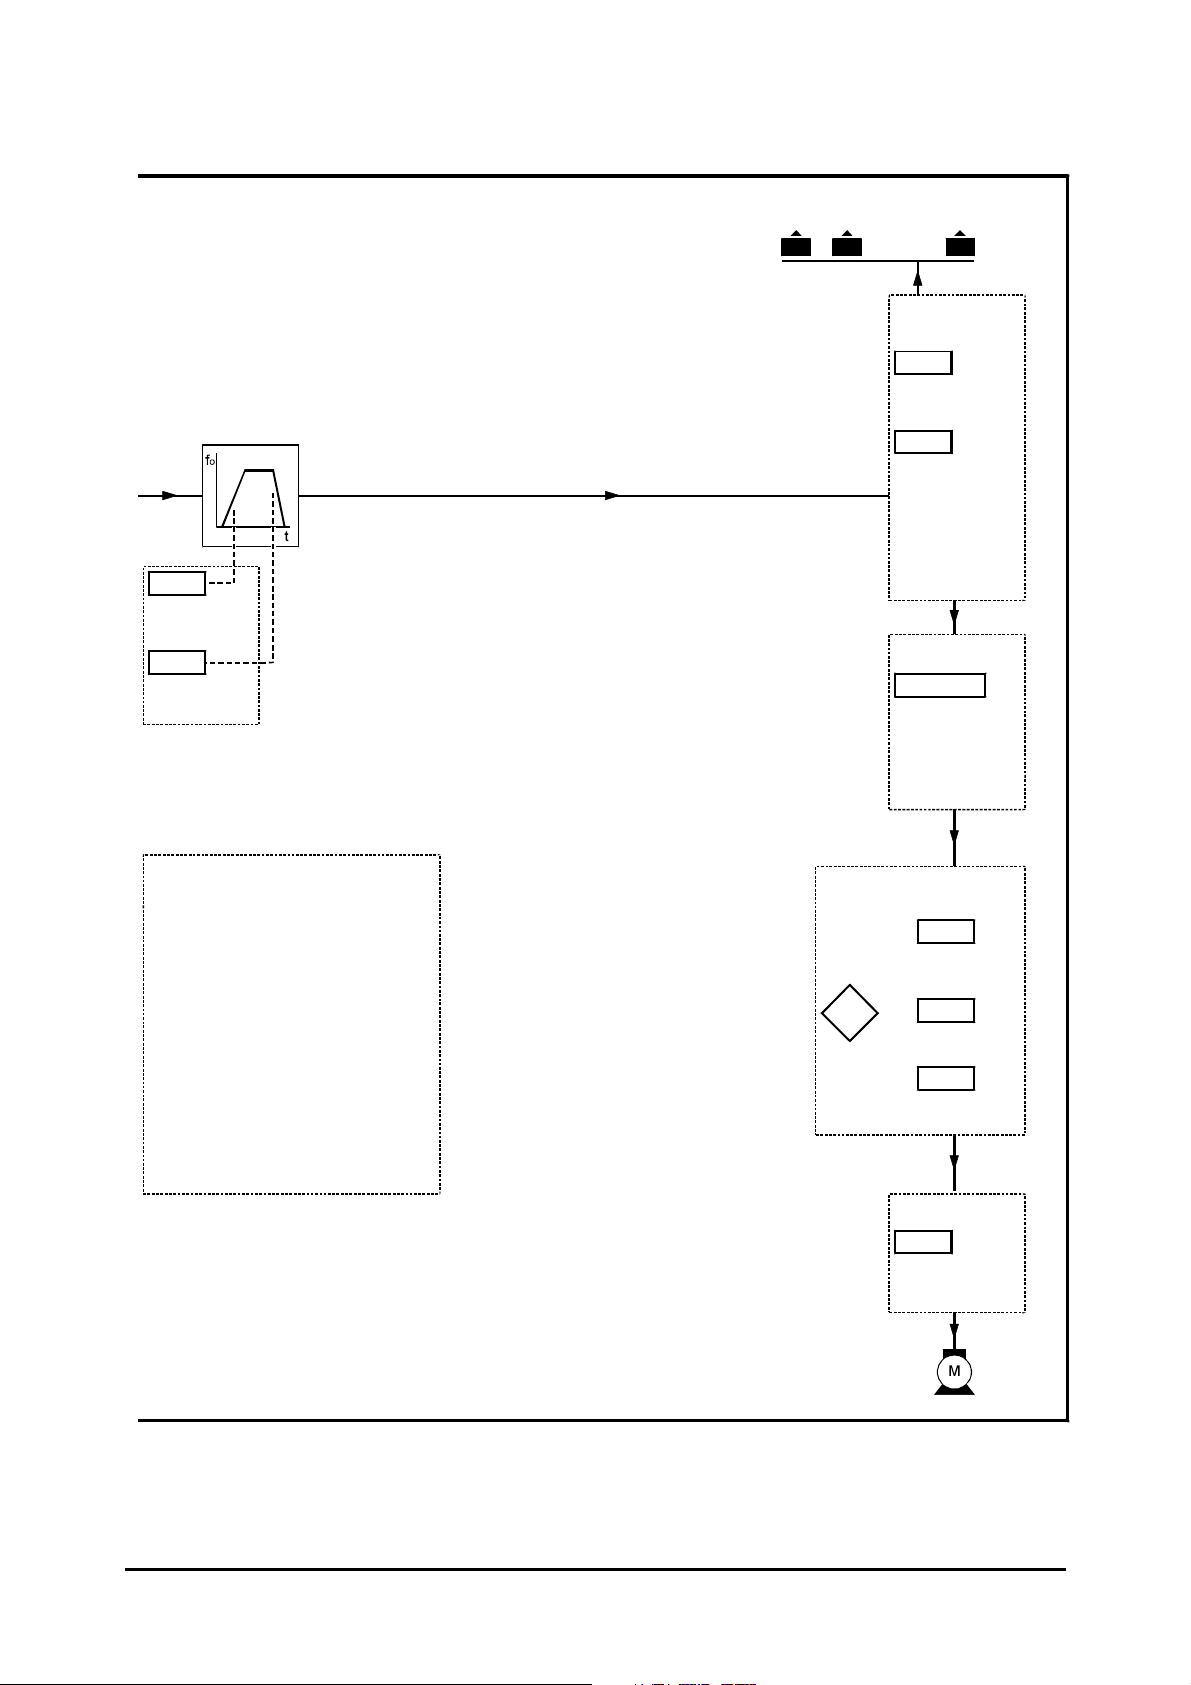
Ramps
0.03
Acceleration
rate
0.04
Deceleration
rate
SPEED TORQUE
9 10 24
AT SPEED
Motor control
0.06
Current
limit
0.39
Synchronize
to a spinning
motor
Motor parameters
0.42 ~ 0.47
No. of poles
Power factor
Rated voltage
Rated speed
Rated current
Rated frequency
Other parameters
0.31 Macro number
0.32 Serial comms. mode
0.33 Drive rated current
0.34 User security code
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.40 Autotune
0.48 Drive software build number
0.49 Security status
0.50 Software version number
Motor-voltage control
Voltage mode
selector
0.10
Estimated
motor
speed
Boost voltage
Dynamic V/f
select
Power stage
0.41
PWM switching
frequency
0.07
0.08
0.09
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-11
Page 40
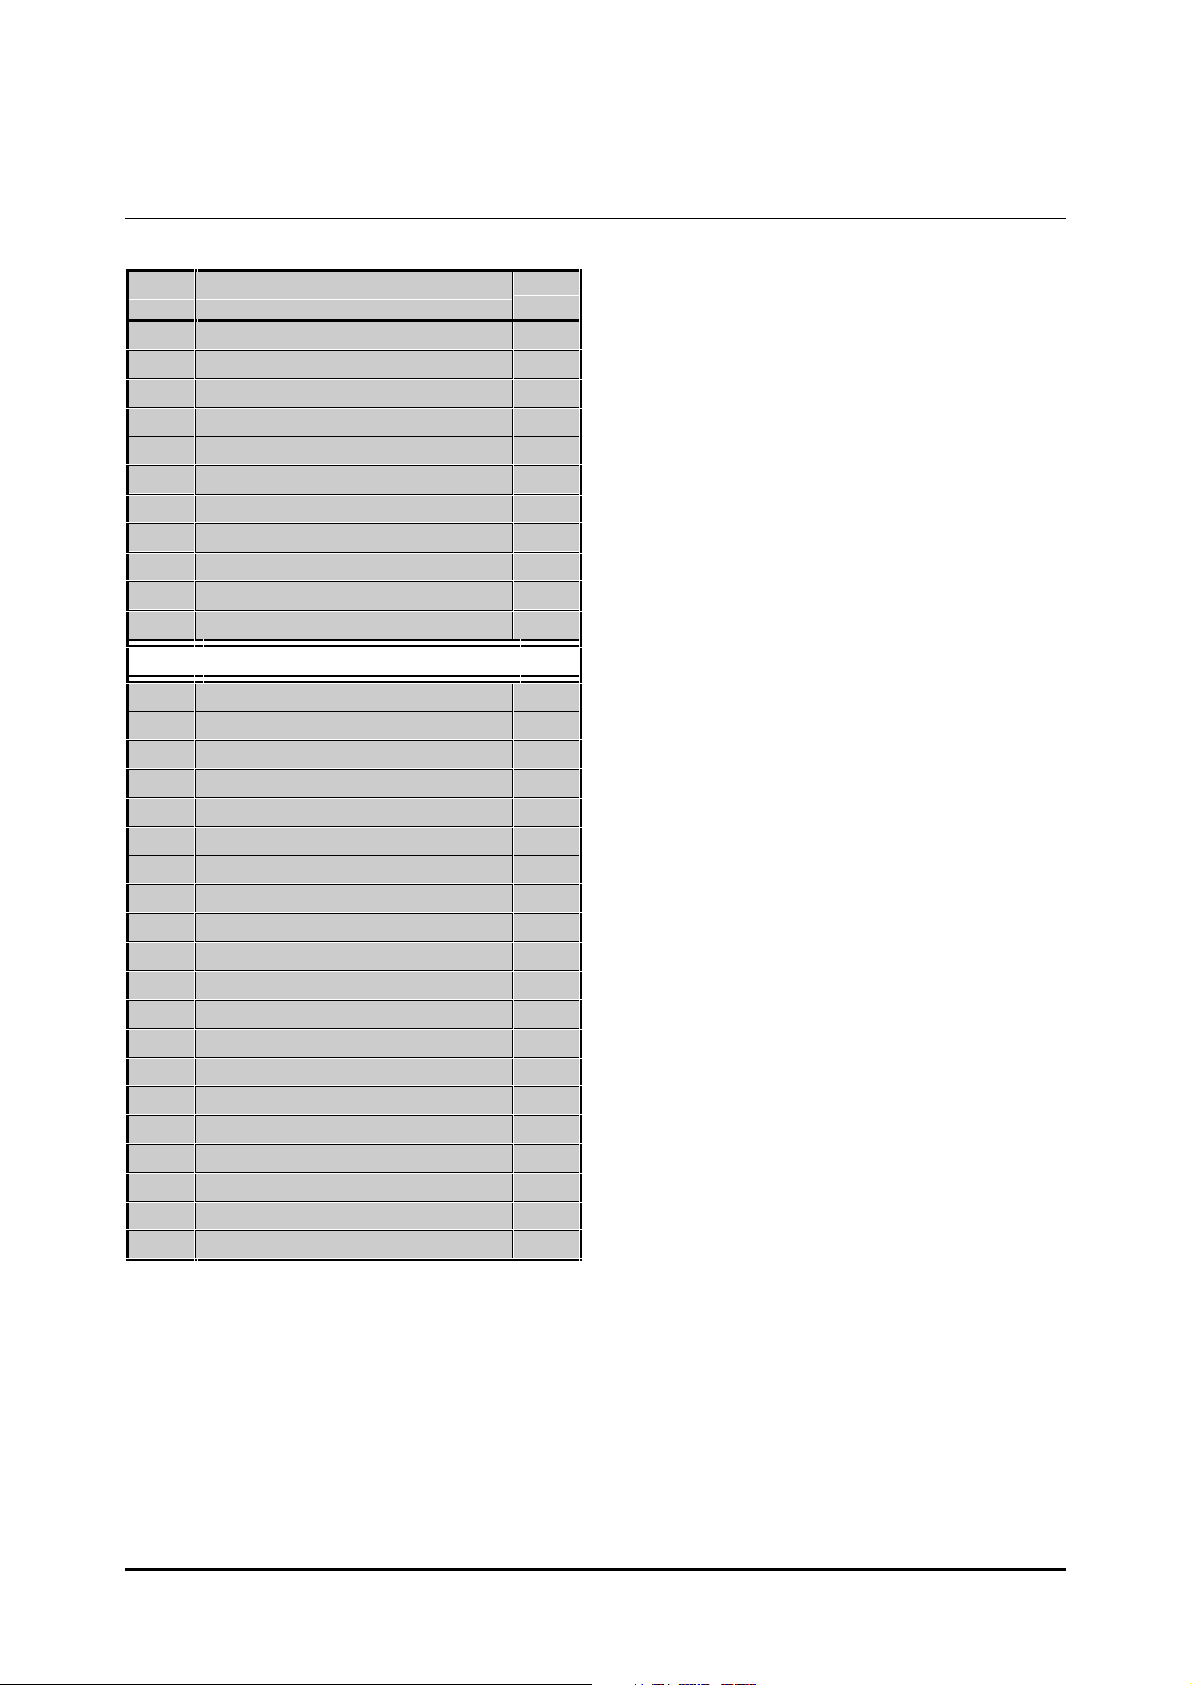
List of parameters specific to Macro 1
Pr Function User
value
0.00 Configuration and saving
0.01 Minimum frequency
0.02 Maximum frequency
0.03 Acceleration rate
0.04 Deceleration rate
0.05 Reference selector
0.06 Current limit
0.07 Voltage mode selector
0.08 Boost voltage
0.09 Dynamic V/f select
0.10 Estimated motor speed [M]
0.31 Macro number [M]
0.32 Serial comms. mode
0.33 Drive rated current (FLC) [M]
0.34 User security code [M]
0.35 Keypad reference [M]
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.38 Initial parameter displayed
0.39 Synchronize to a spinning motor
0.40 Autotune
0.41 PWM switching frequency selector
0.42 Motor – number of poles
0.43 Motor – power factor
0.44 Motor – rated voltage
0.45 Motor – rated speed
0.46 Motor – rated current
0.47 Motor – rated frequency
0.48 Drive software build number [M]
0.49 Security status [M]
0.50 Drive software version [M]
[M] indicates the parameter is for monitoring only
For descriptions of these parameters, see Appendix D Menu
0 Parameters.
3-12 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 41
Setting up and using Macro 1
The following may require attention in addition to
the settings made in Chapter 2.
Reference selection
Use 0.05 Reference selector to select the required
frequency source, as follows:
0.05 Source Terminal(s)
0 Analog input 1 or 2 which can be
selected using the LOCAL/REMOTE
contact
1 Analog input 1 5, 6
2 Analog input 2 7
3 (Do not use)
4 Keypad control
5 (Do not use)
Frequency references
Keypad mode
The value of the keypad reference can be read by
displaying the value of 0.35 Keypad reference.
5 and 6, or 7
Terminal mode
Frequency reference 1 (terminals 5, 6) is configured
for 0 to 10V signal.
Frequency reference 2 (terminal 7) is configured for
4 to 20mA signal. Loss of the current signal will be
treated as zero reference.
Jog
To use jog, close the JOG SELECT contact
(terminal 26) before closing the RUN FORWARD
contact (terminal 27) or RUN REVERSE contact
(terminal 28).
Jog will occur at 1.5Hz. This value cannot be altered.
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-13
Page 42
Use this free space for notes
3-14 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 43
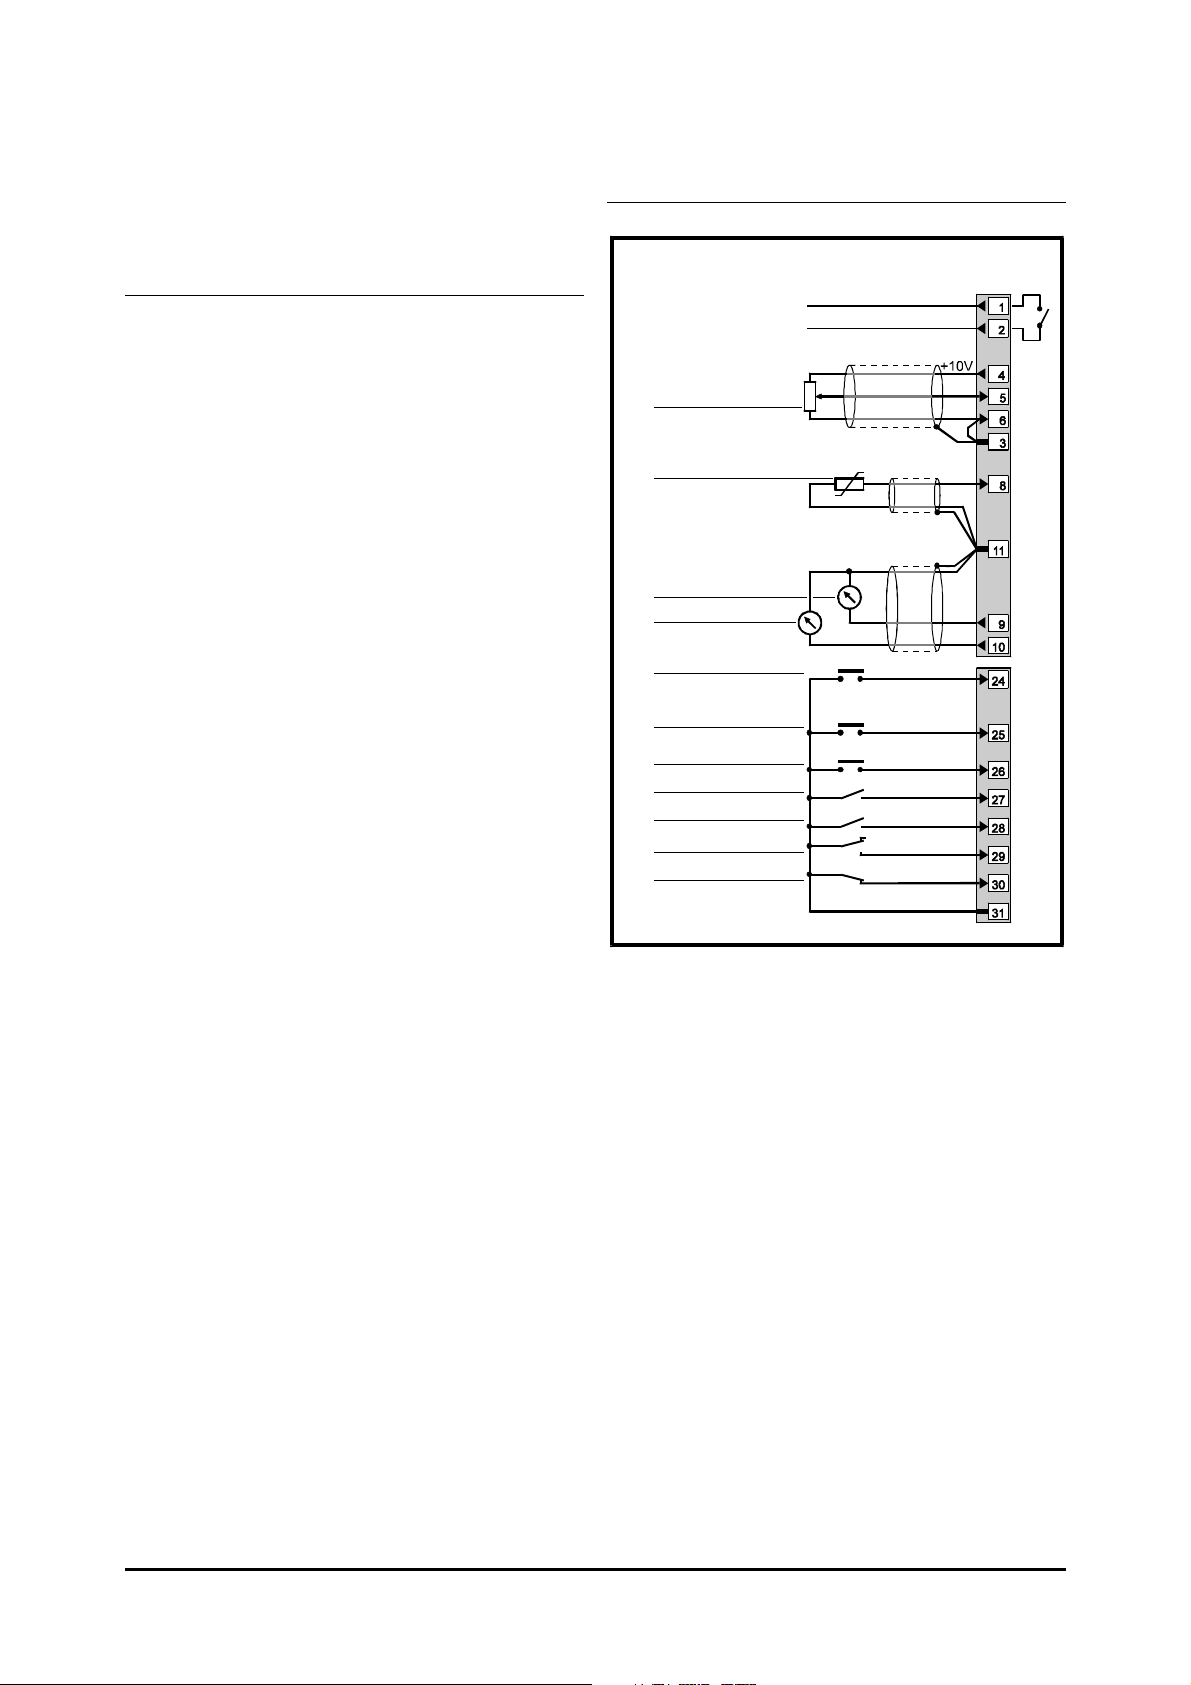
3.5 Macro 2
Motorized potentiometer
Features
Special features
The digital inputs are configured to accept
momentary UP and DOWN contacts.
Selection can be made between motorized
potentiometer operation and normal frequency
control. In both cases, analog input 1 remains
configured for an analog frequency reference signal
(0 to 10V).
Motorized potentiometer is used by first closing the
RUN FORWARD or RUN REVERSE contact as
required, then closing the UP or DOWN contact to
increase or decrease the speed. When the UP and
DOWN contacts are both open, the Drive maintains
constant speed until the closed RUN contact is
opened.
The output of the motorized potentiometer can be
monitored by reading the value of 0.26 Motorized
pot. output indicator, and the frequency by reading
the value of 0.11 Pre-ramp reference.
The motorized potentiometer is reset when the
RESET contact connected to terminal 25 is closed
momentarily. (This also resets the Drive.)
Selection can be made for the motorized
potentiometer to return to the previous set speed,
or start at zero, after each power-up.
Standard features
• Macro 2 operates in Terminal mode only
• Digital control by RUN FORWARD and
RUN REVERSE contacts
• Analog frequency input
• Adjustment of minimum and maximum
frequencies
• Adjustment of acceleration and deceleration
ramps
• S-ramp
• Skip frequencies
• Selection of stopping modes
• Selection of braking mode
• Motor thermistor input
• Negative logic for the digital inputs
• SPEED and TORQUE analog outputs
• External trip digital input
• Drive RESET digital input
Signal connections for Macro 2
Signal
connector
Status relay
Drive healthy
Analog frequency
reference 1
(remote) 0 ~ 10V
Motor thermistor
SPEED
TORQUE
UP
RESET and
MOT. POT. RESET
DOWN
RUN FORWARD
RUN REVERSE
MOT. POT. ENABLE
External trip
Figure 3–6 Control signal and thermistor
connections for Macro 2
For electrical specifications, refer to Appendix C
Signal Connections.
0V common
0V common
ANALOG I/P
MOT. POT.
0V common
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-15
Page 44
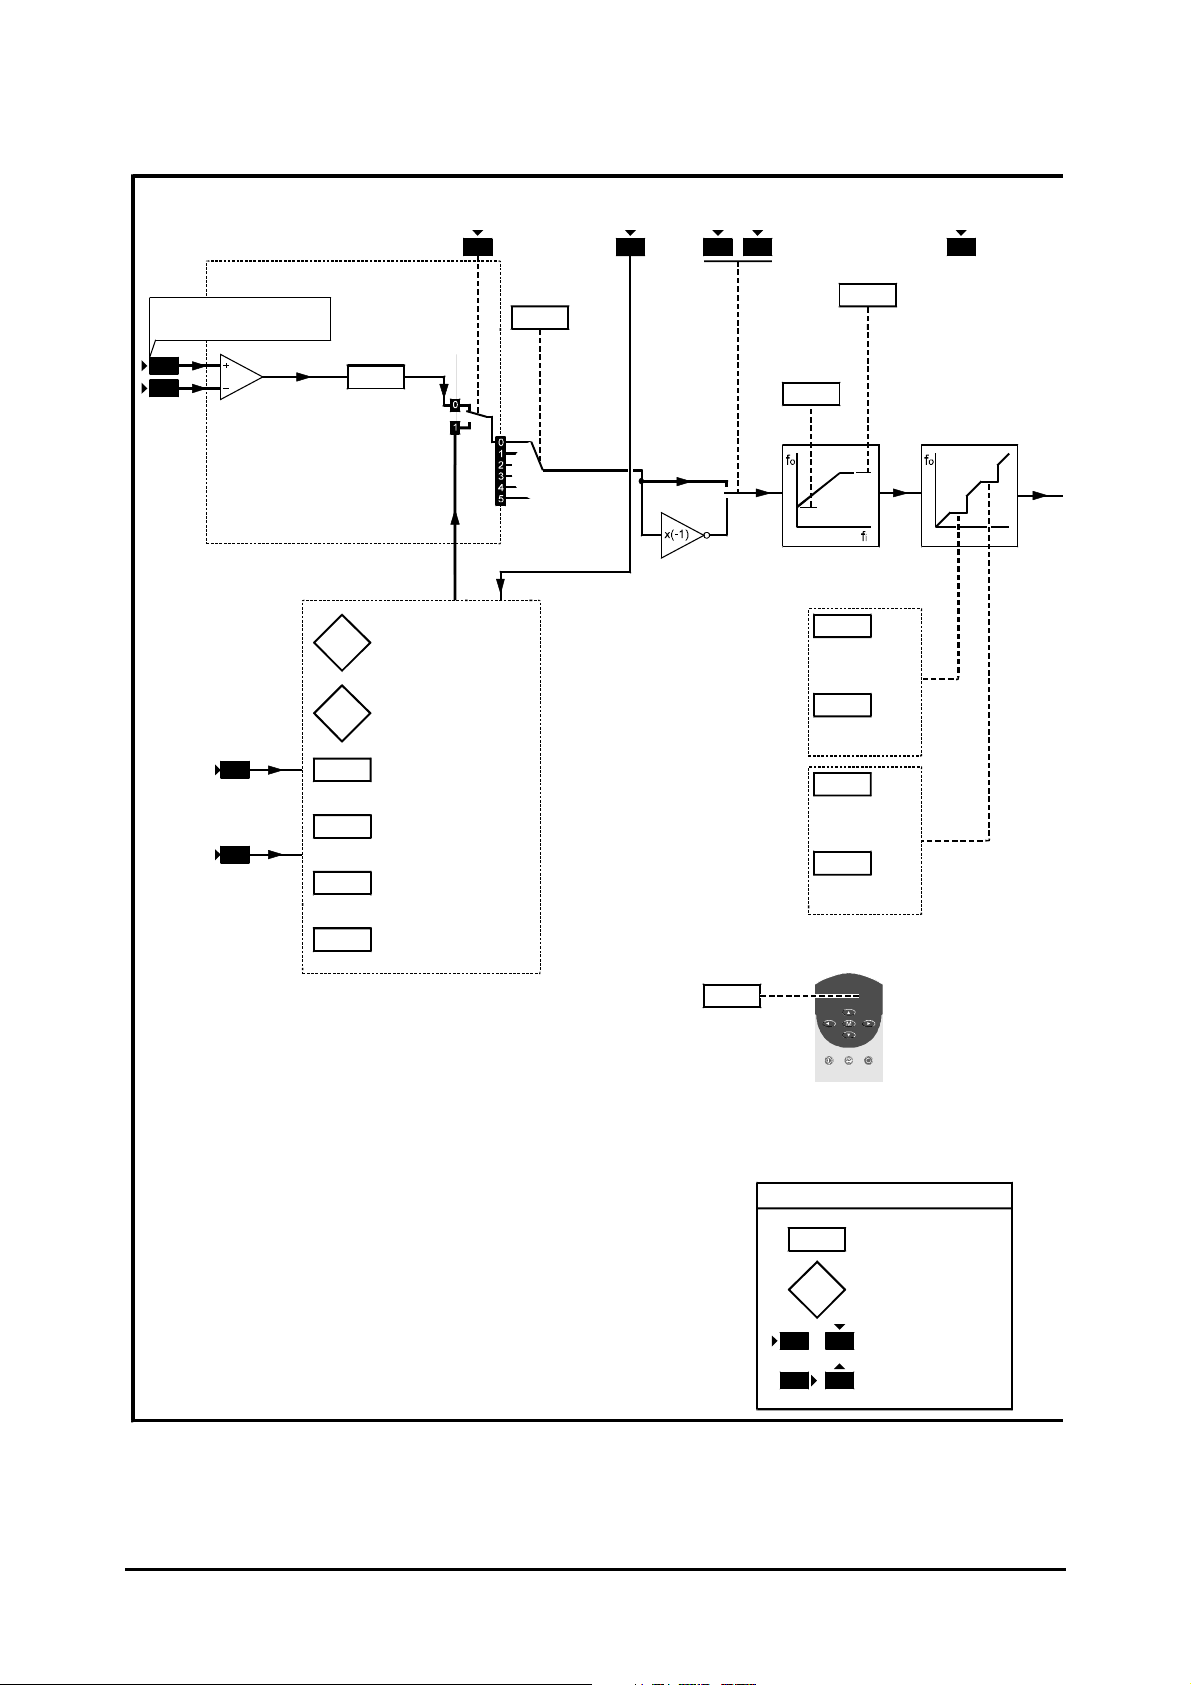
Reference selection
Frequency reference 1
(remote)
5
6
MOTORIZED
POT. ENABLE
Analog input 1
mode
selector
0.24
29
Reference
selector
RESET and
MOT. POT. RESET
25
0.05
RUN
FORWARD
27 28
RUN
REVERSE
Minimum
frequency
0.01
0.02
EXTERNAL TRIP
30
Maximum
frequency
Skip
frequencies
DOWN
Motorized pot.
0.25
reset
indicator
Motorized pot.
0.26
24UP
26
0.27
0.28
0.29
0.30
indicator
output
Motorized pot.
zero-start
Motorized pot.
bipolar
Motorized pot. rate
Motorized pot.
output scale factor
select
select
0.38
Initial
parameter
displayed
0.20
Skip
frequency 1
0.21
Skip band 1
0.22
Skip
frequency 2
0.23
Skip band 2
Key
The parameters are shown at their default settings.
The logic diagram is valid when all parameters are
at their default settings but may not be valid when
certain parameters are adjusted.
Figure 3–7 Programmable software for Macro 2
3-16 Setting Up the Drive
0.XX
0.XX
X X
X X
Read-write (RW)
parameter
Read-only (RO)
parameter
Input terminals
Output terminals
Commander GP User Guide
Issue code: gpxu2
Page 45
Pre-ramp
reference
0.11 0.12
S-ramp
S-ramp
enable
0.18
0.19
S-ramp
da/dt limit
0.03
Acceleration
rate
0.04
Deceleration
rate
0.15
Ramp mode
selector
Ramps
Post-ramp
reference
THERMISTOR
8
SPEED TORQUE
9 10
Motor control
0.06
Current
limit
0.16
Stop mode
selector
0.39
Synchronize
to a spinning
motor
Motor parameters
0.42 ~ 0.47
No. of poles
Power factor
Rated voltage
Rated speed
Rated current
Rated frequency
Other parameters
0.17 Status relay
0.31 Macro number
0.32 Serial comms. mode
0.33 Drive rated current
0.34 User security code
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.40 Autotune
0.48 Drive software build number
0.49 Security status
0.50 Software version number
invert
0.10
Estimated
motor
speed
Motor
active-current
0.13
Motor-voltage control
0.07
Voltage mode
selector
0.08
Boost voltage
0.09
Dynamic V/f
select
Power stage
0.41
PWM switching
frequency
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-17
Page 46
List of parameters specific to Macro 2
Pr Function User
value
0.00 Configuration and saving
0.01 Minimum frequency
0.02 Maximum frequency
0.03 Acceleration rate
0.04 Deceleration rate
0.05 Reference selector (do not adjust)
0.06 Current limit
0.07 Voltage mode selector
0.08 Boost voltage
0.09 Dynamic V/f select
0.10 Estimated motor speed [M]
Pr Function User
value
0.31 Macro number [M]
0.32 Serial comms. mode
0.33 Drive rated current (FLC) [M]
0.34 User security code [M]
0.35 Keypad reference [M]
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.38 Initial parameter displayed
0.39 Synchronize to a spinning motor
0.40 Autotune
0.41 PWM switching frequency selector
0.42 Motor – number of poles
0.43 Motor – power factor
0.44 Motor – rated voltage
0.45 Motor – rated speed
0.46 Motor – rated current
0.47 Motor – rated frequency
0.48 Drive software build number [M]
0.49 Security status [M]
0.50 Drive software version [M]
[M] indicates the parameter is for monitoring only
For descriptions of these parameters, see
Appendix D Menu 0 Parameters.
Pr Function User
value
0.11 Pre-ramp reference [M]
0.12 Post-ramp reference [M]
0.13 Motor active-current [M]
0.14 Jog reference (not used)
0.15 Ramp mode selector
0.16 Stop mode selector
0.17 Status relay invert
0.18 S-ramp enable
0.19 S-ramp da/dt
0.20 Skip frequency 1
0.21 Skip band 1
0.22 Skip frequency 2
0.23 Skip band 2
0.24 Analog input 1 mode selector
0.25 Motorized pot. reset indicator [M]
0.26 Motorized pot. output indicator
0.27 Motorized pot. zero-start select
0.28 Motorized pot. bipolar select
0.29 Motorized pot. rate
0.30 Motorized pot. output scale factor
3-18 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 47
Setting up and using Macro 2
Setting
Stnd.Ct
rP
Reference selection
The following may require attention in addition to
the settings made in Chapter 2.
Motorized potentiometer settings
1. By default, the Drive operates in frequency
control. To disable this and enable the
motorized potentiometer, close the MOT. POT.
ENABLE contact (terminal 29).
2. If required, change the value of 0.29 Motorized
pot. rate to change the rate of increase and
decrease. Increasing the value reduces the rate
of change of frequency.
Default value: 20 s
Range: 0 ~ 250 s
3. If bipolar operation is required, set 0.28
Motorized pot. bipolar select at 1.
4. By default, every time the Drive is powered-up
and enabled, the frequency will return under
ramp control to the last setting of the
motorized potentiometer. If the Drive is
required to start at zero, set 0.27 Motorized
pot. zero-start select at 1.
5. To reset the motorized potentiometer,
momentarily close the RESET contact. (This
also resets the Drive.)
6. If required, change the scaling of the
motorized potentiometer output by adjusting
0.30 Motorized pot. output scale factor.
7. If required, monitor the output value of the
potentiometer by reading 0.26 Motorized pot.
output indicator.
For correct operation of this macro configuration,
the setting of parameter of 0.05 Reference selection
should be at 0.
Analog input modes
The analog input can be configured for the
following input signals:
0 ~ 20mA, 4 ~ 20mA or 0 ~ 10V
Refer to the following parameter in Appendix D
Menu 0 Parameters for selecting the required mode:
Analog
input
1 5, 6
Terminal(s) Parameter
0.24
Analog input 1 mode selector
Jog frequency
There is no need to adjust 0.14 Jog reference since
the jog function cannot be used.
Stopping and braking modes
Refer to the following parameters in Appendix D
Menu 0 Parameters:
Parameter
0.150.15
Ramp mode selector
0.160.16
Stop mode selector
Function
(Standard controlled)
Deceleration time is
extended if the
voltage reaches its
maximum permissible
value during braking.
Ramp to stop then the
Drive is disabled
DC-bus
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-19
Page 48
Use this page for notes
3-20 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 49
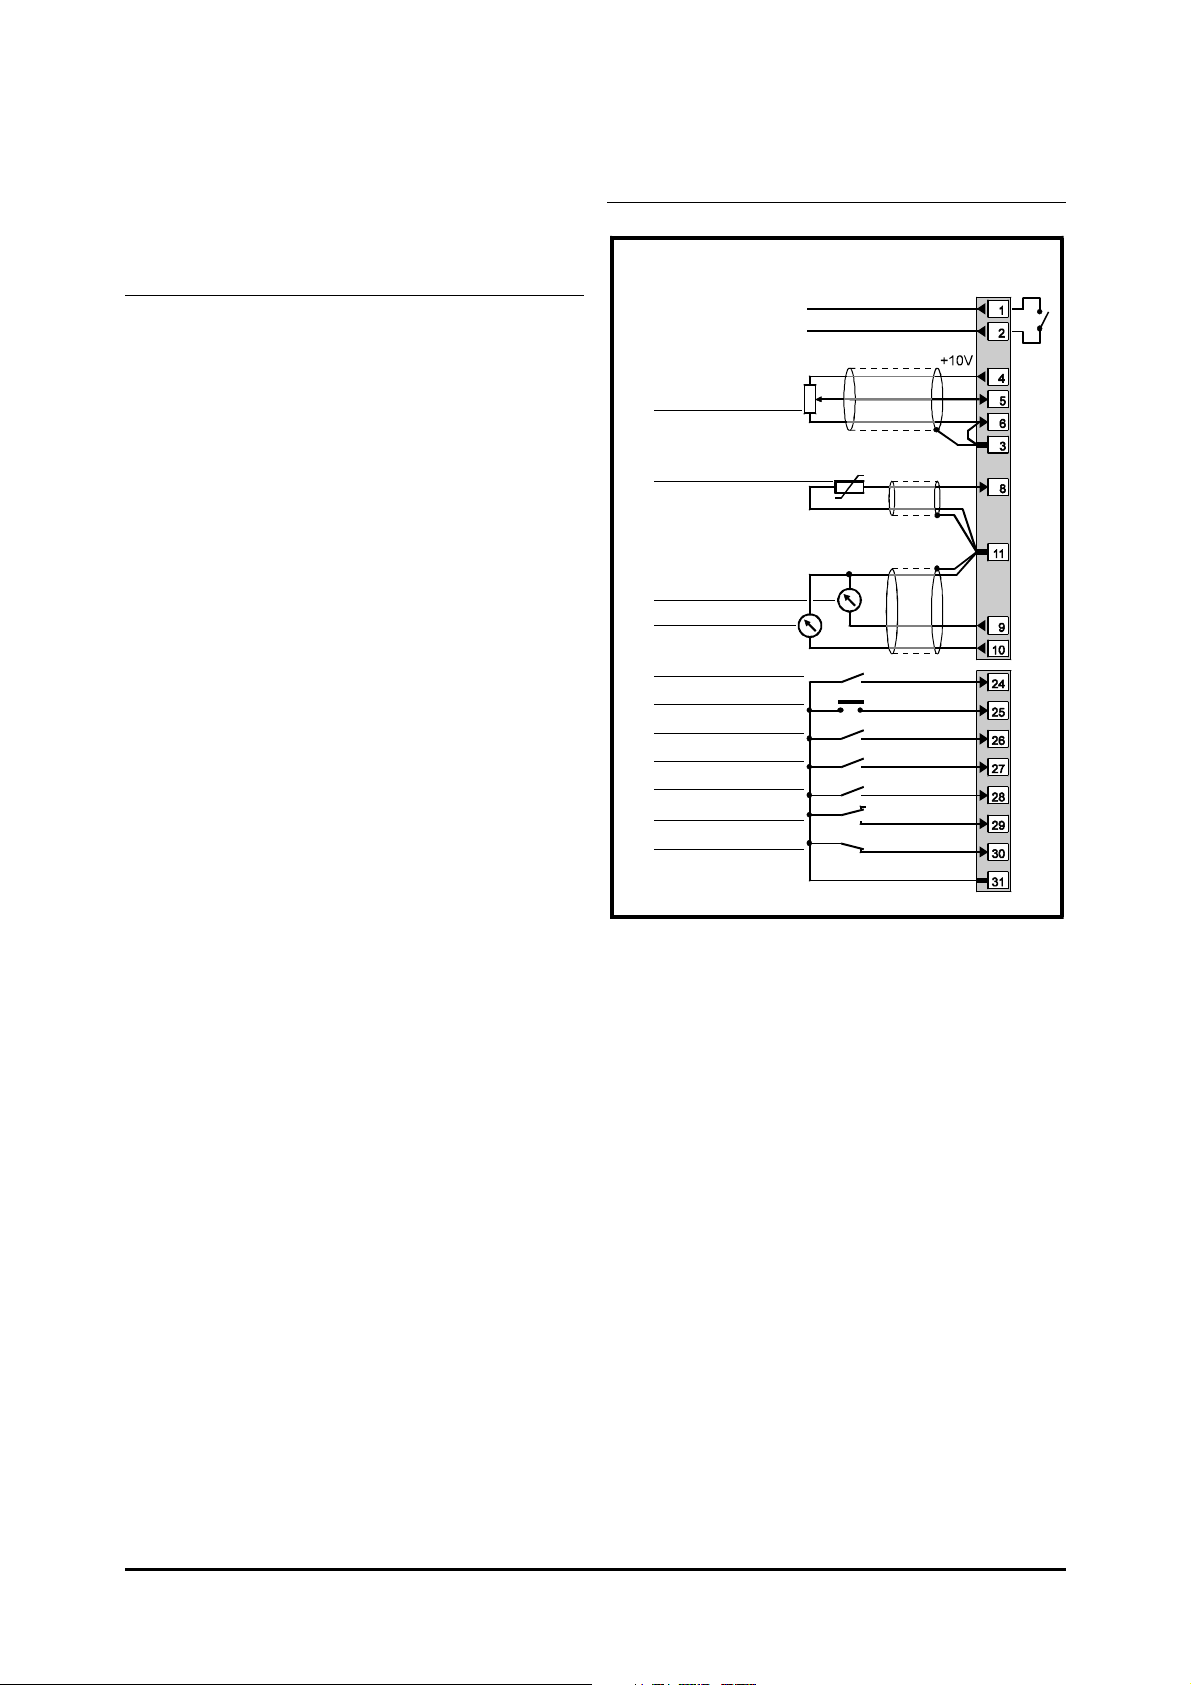
3.6 Macro 3
Preset frequencies
Features
Special features
Signal connections for Macro 3
Status relay
Drive healthy
Signal
connector
Selection can be made between preset frequencies
and analog frequency control. In both cases, analog
input 1 remains configured for an analog frequency
reference signal (0 to 10V).
Up to four preset frequencies can be used; their
values must be programmed into individual
parameters. Selection is made by external contacts
operating in binary logic.
Standard features
• Macro 3 operates in Terminal mode only
• Digital control by RUN FORWARD and
RUN REVERSE contacts
• Analog frequency input
• Adjustment of minimum and maximum
frequencies
• Adjustment of acceleration and deceleration
ramps
• Operation of the status relay can
be inverted
• S-ramp
• Skip frequencies
• Selection of stopping modes
• Selection of braking mode
• Motor thermistor input
• Negative logic for the digital inputs
• SPEED and TORQUE analog outputs
• External trip digital input
• Drive RESET digital input
Analog frequency
reference 1
(remote) 0 ~ 10V
Motor thermistor
SPEED
TORQUE
PRESET SELECT
RESET
PRESET SELECT
RUN FORWARD
RUN REVERSE
PRESET ENABLE
External trip
A
B
0V common
0V common
ANALOG I/P
PRESET REFS.
0V common
Figure 3–8 Control signal and thermistor
connections for Macro 3
For electrical specifications, refer to Appendix C
Signal Connections.
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-21
Page 50
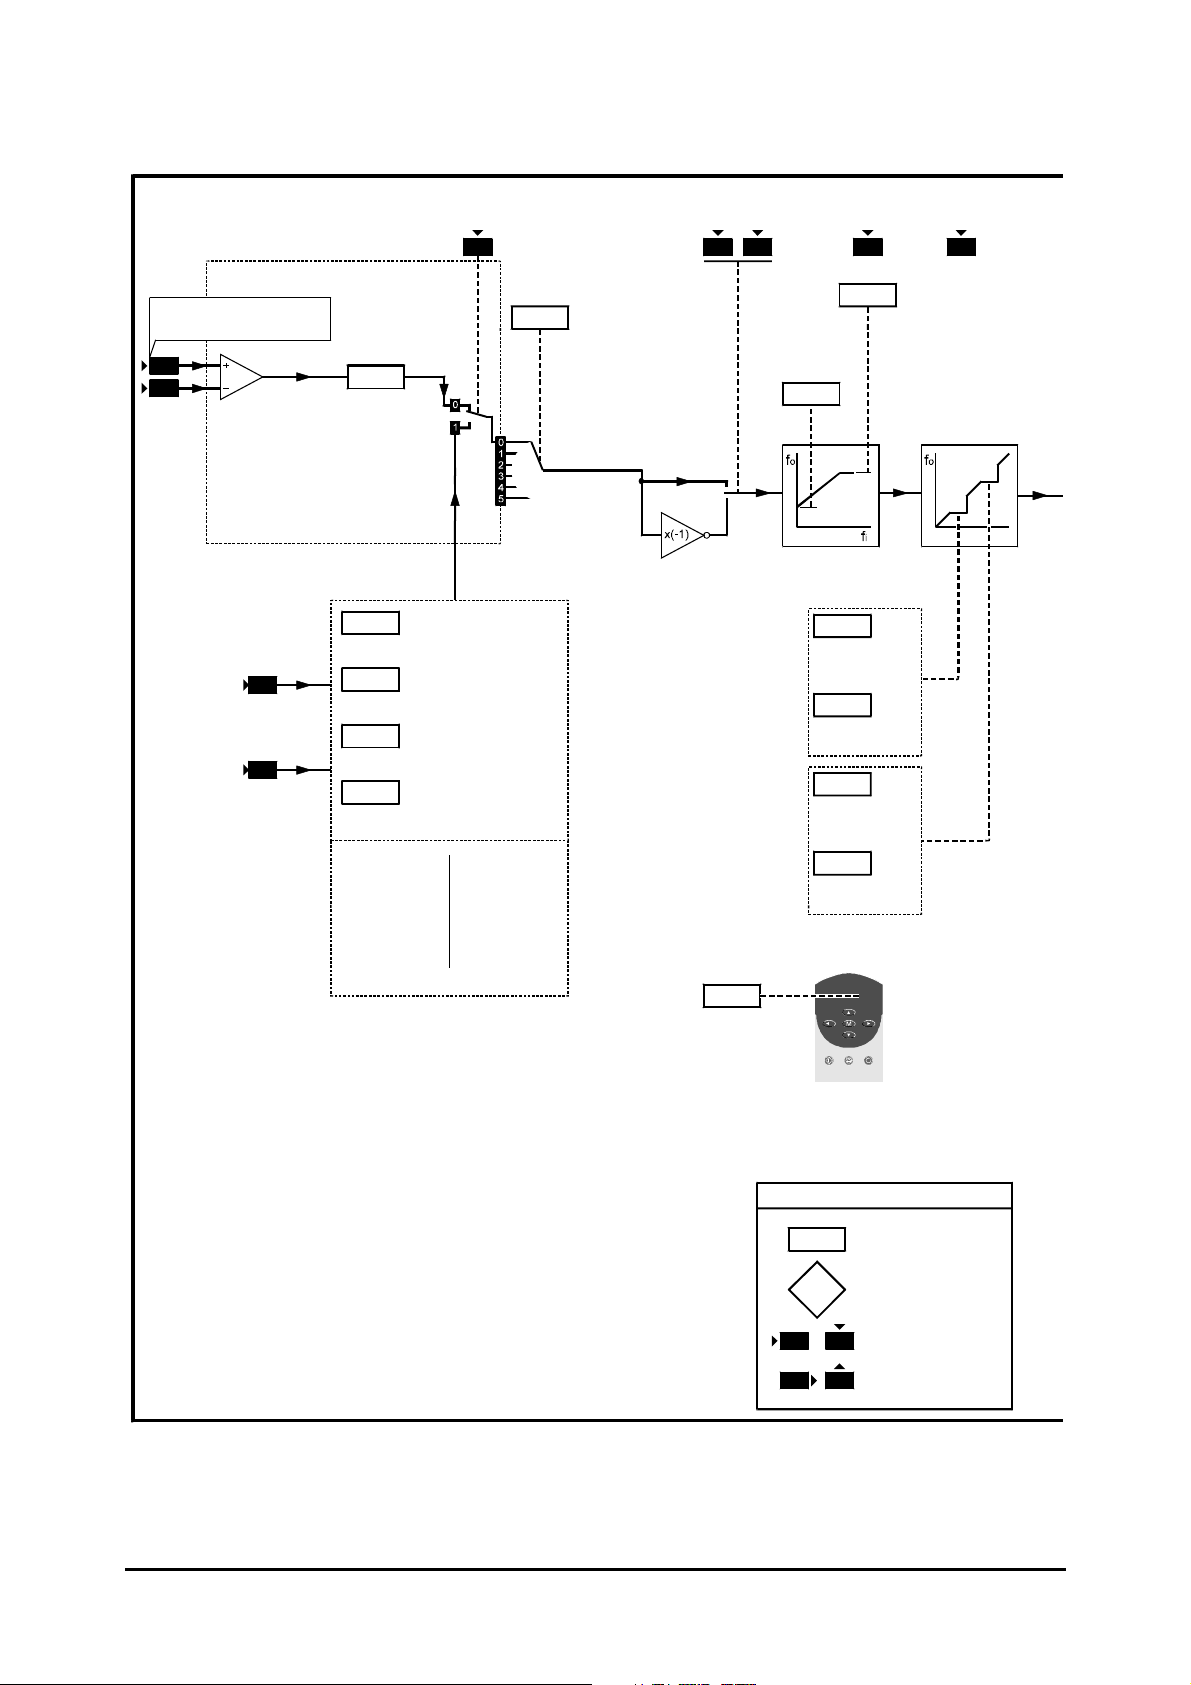
Reference selection
Frequency reference 1
(remote)
5
6
PRESET
SELECT
PRESET
SELECT
24
A
26
B
Analog input 1
mode
selector
0.24
Preset
0.25
reference 1
Preset
0.26
reference 2
Preset
0.27
reference 3
Preset
0.28
reference 4
PRESET
ENABLE
29
Reference
selector
0.05
RUN
FORWARD
27 28
RUN
REVERSE
Minimum
frequency
0.01
0.20
Skip
frequency 1
0.21
Skip band 1
0.22
Skip
frequency 2
RESET
25
0.02
EXTERNAL TRIP
30
Maximum
frequency
Skip
frequencies
A
B
Preset
frequency
0
0
0
1
1
0
1
1
The parameters are shown at their default settings.
The logic diagram is valid when all parameters are
at their default settings but may not be valid when
certain parameters are adjusted.
1
2
3
4
Figure 3–9 Programmable software for Macro 3
0.38
Initial
parameter
displayed
Skip band 2
0.XX
0.XX
X X
X X
0.23
Key
Read-write (RW)
parameter
Read-only (RO)
parameter
Input terminals
Output terminals
3-22 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 51
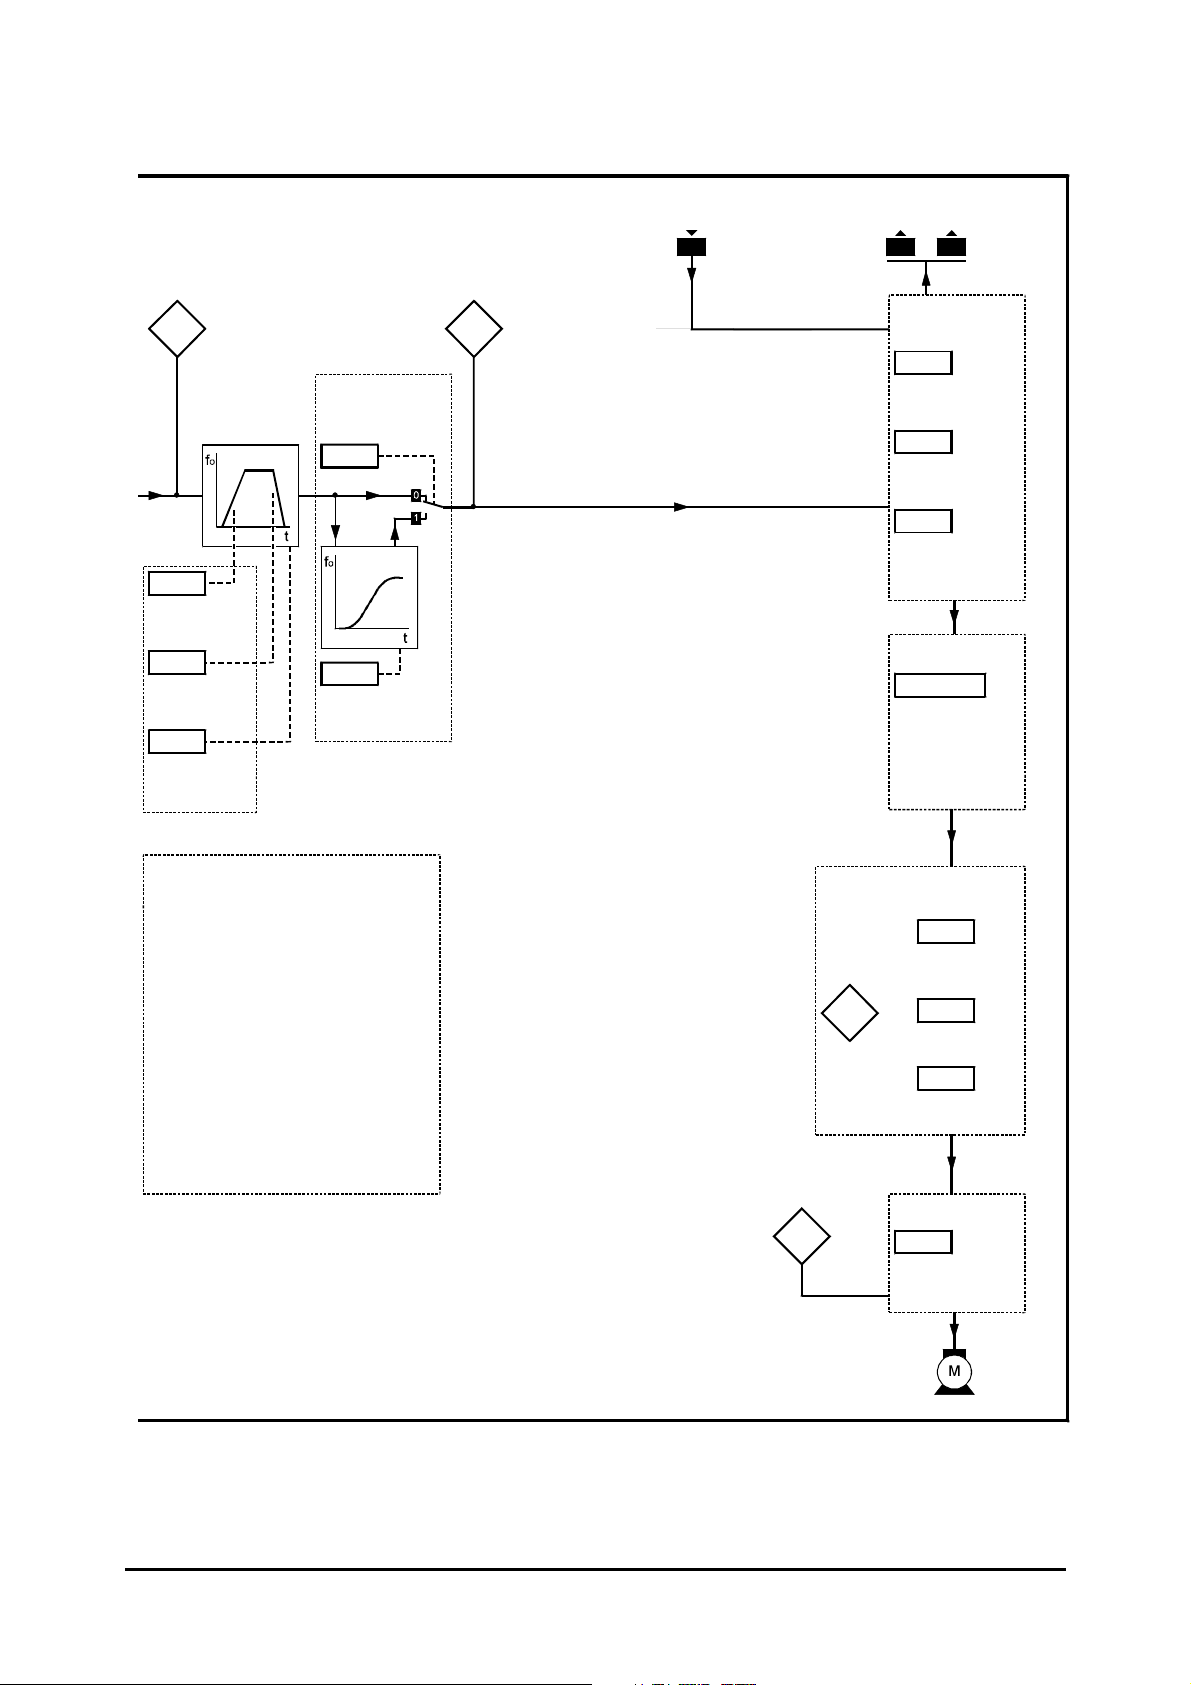
Pre-ramp
reference
0.11 0.12
S-ramp
S-ramp
enable
0.18
0.19
S-ramp
da/dt limit
0.03
Acceleration
rate
0.04
Deceleration
rate
0.15
Ramp mode
selector
Ramps
Post-ramp
reference
THERMISTOR
8
SPEED TORQUE
9 10
Motor control
0.06
Current
limit
0.16
Stop mode
selector
0.39
Synchronize
to a spinning
motor
Motor parameters
0.42 ~ 0.47
No. of poles
Power factor
Rated voltage
Rated speed
Rated current
Rated frequency
Other parameters
0.17 Status relay
0.31 Macro number
0.32 Serial comms. mode
0.33 Drive rated current
0.34 User security code
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.40 Autotune
0.48 Drive software build number
0.49 Security status
0.50 Software version number
invert
0.10
Estimated
motor
speed
Motor
active-current
0.13
Motor-voltage control
0.07
Voltage mode
selector
0.08
Boost voltage
0.09
Dynamic V/f
select
Power stage
0.41
PWM switching
frequency
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-23
Page 52
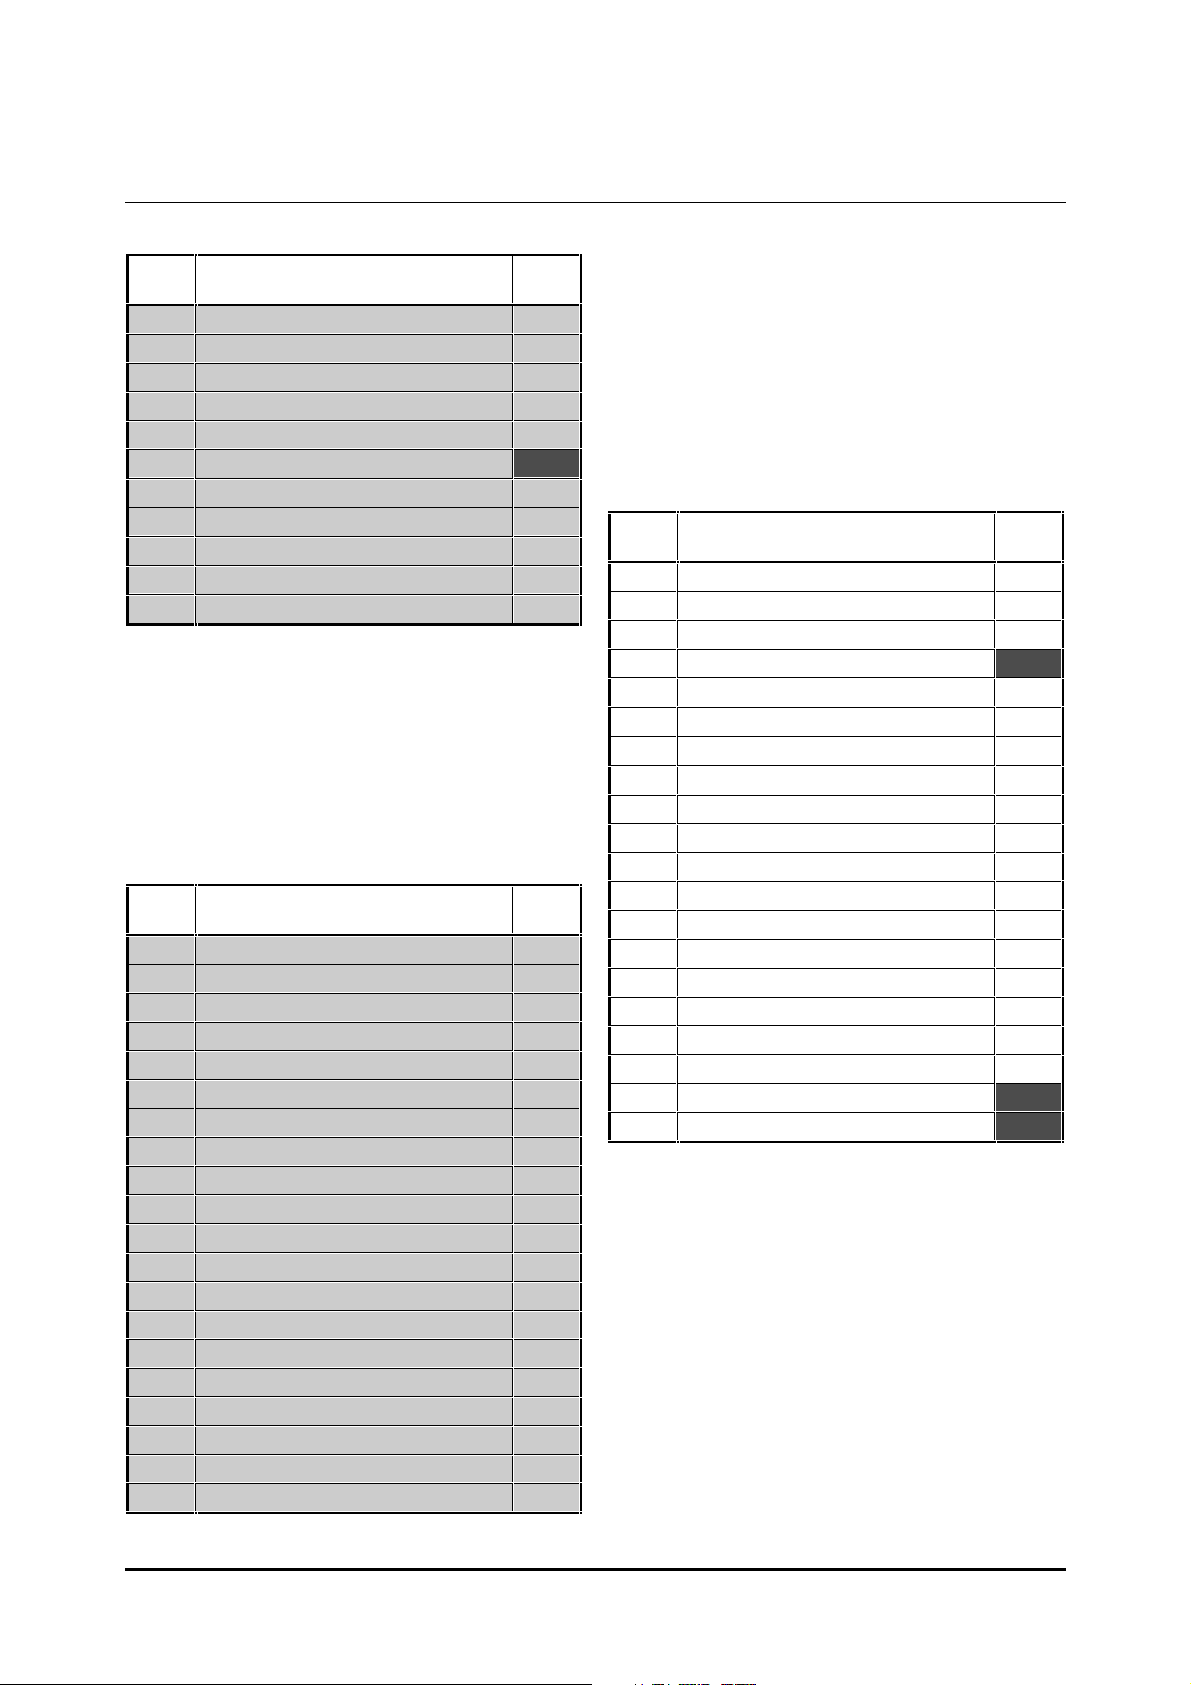
List of parameters specific to Macro 3
Pr Function User
value
0.00 Configuration and saving
0.01 Minimum frequency
0.02 Maximum frequency
0.03 Acceleration rate
0.04 Deceleration rate
0.05 Reference selector (do not adjust)
0.06 Current limit
0.07 Voltage mode selector
0.08 Boost voltage
0.09 Dynamic V/f select
0.10 Estimated motor speed [M]
Pr Function User
value
0.31 Macro number [M]
0.32 Serial comms. mode
0.33 Drive rated current (FLC) [M]
0.34 User security code [M]
0.35 Keypad reference [M]
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.38 Initial parameter displayed
0.39 Synchronize to a spinning motor
0.40 Autotune
0.41 PWM switching frequency selector
0.42 Motor – number of poles
0.43 Motor – power factor
0.44 Motor – rated voltage
0.45 Motor – rated speed
0.46 Motor – rated current
0.47 Motor – rated frequency
0.48 Drive software build number [M]
0.49 Security status [M]
0.50 Drive software version [M]
[M] indicates the parameter is for monitoring only
For descriptions of these parameters, see
Appendix D Menu 0 Parameters.
Pr Function User
value
0.11 Pre-ramp reference [M]
0.12 Post-ramp reference [M]
0.13 Motor active-current [M]
0.14 Jog reference (not used)
0.15 Ramp mode selector
0.16 Stop mode selector
0.17 Status relay invert
0.18 S-ramp enable
0.19 S-ramp da/dt
0.20 Skip frequency 1
0.21 Skip band 1
0.22 Skip frequency 2
0.23 Skip band 2
0.24 Analog input 1 mode selector
0.25 Preset reference 1
0.26 Preset reference 2
0.27 Preset reference 3
0.28 Preset reference 4
0.29 (Not used)
0.30 (Not used)
3-24 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 53
Setting up and using Macro 3
Setting
Stnd.Ct
rP
Reference selection
The following may require attention in addition to
the settings made in Chapter 2.
Preset references
1. By default, the Drive operates in frequency
control. To disable this and enable the preset
references, close the PRESET ENABLE contact
(terminal 29).
2. Enter the required values in the following
parameters:
0.25 Preset frequency 1
0.26 Preset frequency 2
0.27 Preset frequency 3
0.28 Preset frequency 4
Default value: 0
Range: ±1000 Hz
3. Select the required preset reference as follows:
Preset
reference
1 Open Open
2 Open Closed
3 Closed Open
4 Closed Closed
PRESET SELECT A
(terminal 24)
PRESET SELECT B
(terminal 26)
For correct operation of this macro configuration,
the setting of parameter of 0.05 Reference selection
should be at 0.
Analog input modes
The analog input can be configured for the
following input signals:
0 ~ 20mA, 4 ~ 20mA or 0 ~ 10V
Refer to the following parameter in Appendix D
Menu 0 Parameters for selecting the required mode:
Analog
input
1 5, 6
Terminal(s) Parameter
0.24
Analog input 1 mode selector
Jog frequency
There is no need to adjust 0.14 Jog reference since
the jog function cannot be used.
Stopping and braking modes
Refer to the following parameters in Appendix D
Menu 0 Parameters:
Parameter
0.150.15
Ramp mode selector
0.160.16
Stop mode selector
Function
(Standard controlled)
Deceleration time is
extended if the
voltage reaches its
maximum permissible
value during braking.
Ramp to stop then the
Drive is disabled
DC-bus
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-25
Page 54
Use this free space for notes
3-26 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 55
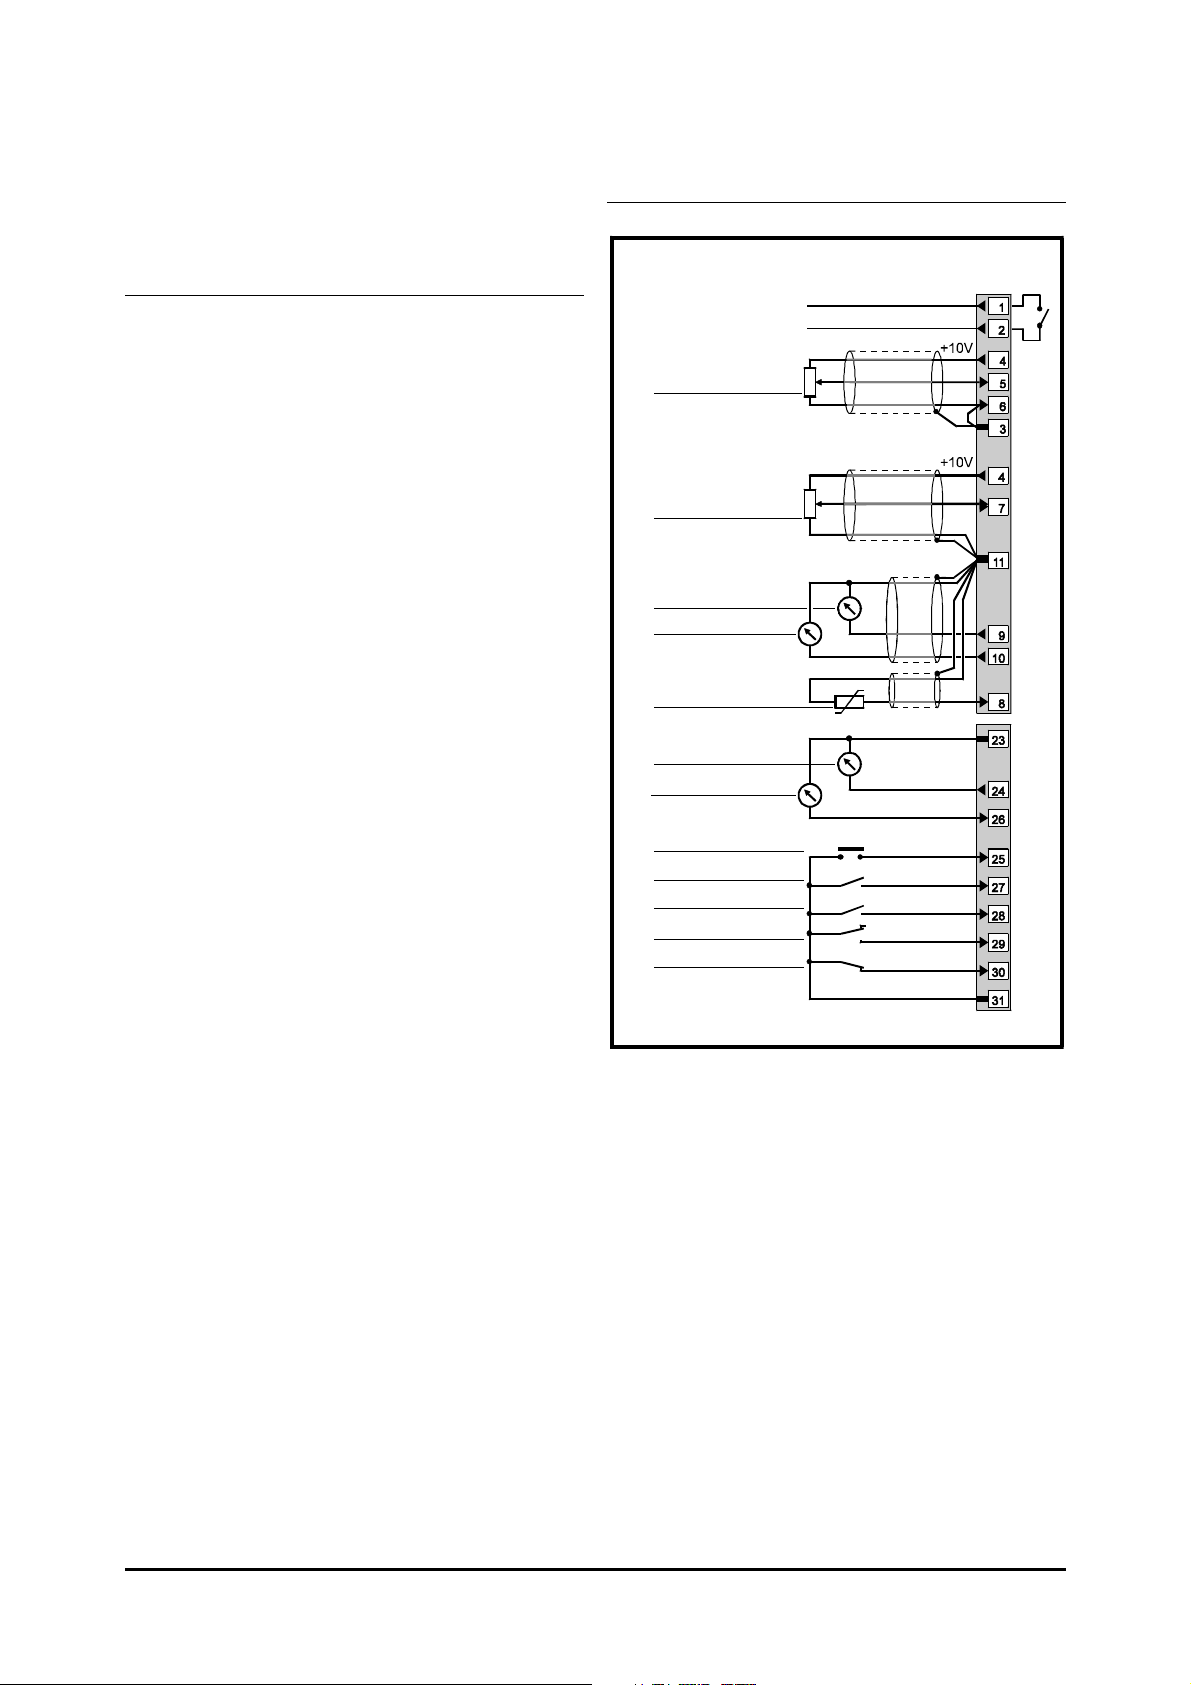
3.7 Macro 4
Torque control
Features
Specific features
Signal connections for Macro 4
Status relay
Drive healthy
Signal
connector
Selection can be made between torque control and
frequency control.
When frequency control is selected, the Drive will
run at the frequency demand irrespective of load so
long as the maximum permissible output current of
the Drive is not reached. The frequency reference
must be applied to analog input 2.
When torque control is selected, analog input 1 is
configured for an analog torque reference. The
maximum frequency is limited to the value of
0.02 Maximum frequency. Analog input 2 is not used.
Both inputs accept 0 to 10V.
Torque slaving
Macro 4 can be used in applications where two or
more motors are mechanically linked and must share
the torque load in a controlled way.
Standard features
• Macro 4 operates in Terminal mode only
• Digital control by RUN FORWARD and
RUN REVERSE contacts
• Analog torque and frequency inputs
• Adjustment of maximum frequencies
• Adjustment of acceleration and deceleration
ramps
• Operation of the status relay can
be inverted
• Selection of braking mode
• Motor thermistor input
• Negative logic for the digital inputs
• SPEED and TORQUE analog outputs
• AT MINIMUM SPEED digital output
• AT SPEED digital output
• External trip digital input
• Drive RESET digital input
Analog torque
reference 1 (0 ~ 10V)
0V common
Analog frequency
reference 1 (0 ~ 10V)
0V common
SPEED
TORQUE
Motor thermistor
AT SPEED
AT MIN. SPEED
RESET
RUN FORWARD
RUN REVERSE
TORQUE ENABLE
External trip
0V common
FREQUENCY CONTROL
TORQUE CONTROL
0V common
Figure 3–10 Control signal and thermistor
connections for Macro 4
For electrical specifications, refer to Appendix C
Signal Connections.
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-27
Page 56
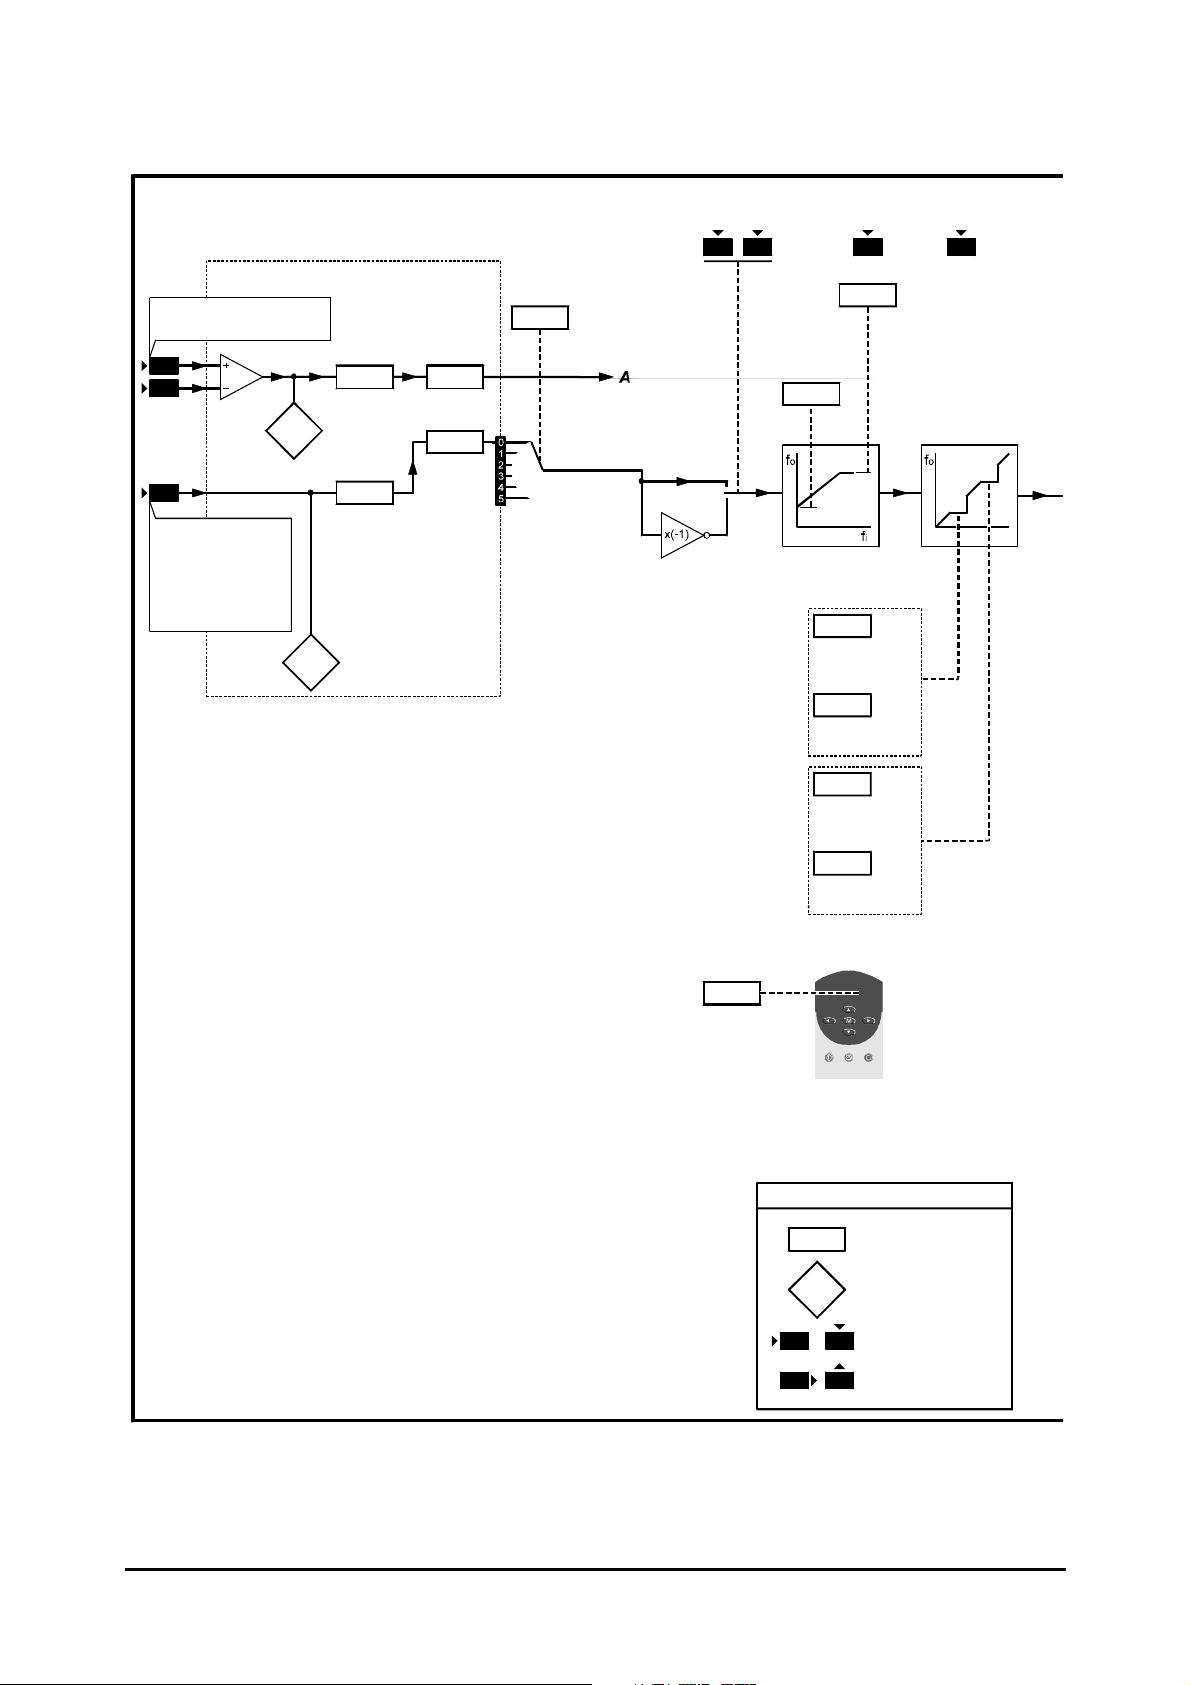
Reference selection
Analog torque
reference
5
6
7
Frequency control:
Frequency reference
Torque control:
(Not used)
RUN
FORWARD
Reference
Analog
input 1
mode
selector
0.24
Analog
0.25
input 1
0.26
0.27
Analog
input 2
mode
selector
Analog
input 2
Analog
input 1
scaling
0.29
0.30
Analog
input 2
scaling
selector
0.05
RUN
REVERSE
27 28
Minimum
frequency
0.01
0.20
Skip
frequency 1
0.21
Skip band 1
0.22
Skip
frequency 2
RESET
EXTERNAL TRIP
25 30
Frequency over-ride
0.02
frequencies
Skip
The parameters are shown at their default settings.
The logic diagram is valid when all parameters are
at their default settings but may not be valid when
certain parameters are adjusted.
Figure 3–11 Programmable software for Macro 4
0.38
Initial
parameter
displayed
Skip band 2
0.XX
0.XX
X X
X X
0.23
Key
Read-write (RW)
parameter
Read-only (RO)
parameter
Input terminals
Output terminals
3-28 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 57
Pre-ramp
reference
S-ramp
S-ramp
enable
0.18
0.19
S-ramp
da/dt limit
Post-ramp
reference
0.11 0.12
Ramps
0.03
Acceleration
rate
0.04
Deceleration
rate
0.15
Ramp mode
selector
TORQUE
ENABLE
29
THERMISTOR
8
SPEED TORQUE
9 10 24
AT SPEED
AT MIN.
SPEED
26
Motor control
0.06
Current
limit
0.16
Stop mode
selector
0.39
Synchronize
to a spinning
motor
Motor parameters
0.42 ~ 0.47
No. of poles
Power factor
Rated voltage
Rated speed
Rated current
Rated frequency
Other parameters
0.17 Status relay
0.28 Over-speed threshold
0.31 Macro number
0.32 Serial comms. mode
0.33 Drive rated current
0.34 User security code
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.40 Autotune
0.48 Drive software build number
0.49 Security status
0.50 Software version number
invert
0.10
Estimated
motor
speed
Motor
active-current
0.13
Motor-voltage control
0.07
Voltage mode
selector
0.08
Boost voltage
0.09
Dynamic V/f
select
Power stage
0.41
PWM switching
frequency
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-29
Page 58
List of parameters specific to Macro 4
Pr Function User
value
0.00 Configuration and saving
0.01 Minimum frequency
0.02 Maximum frequency
0.03 Acceleration rate
0.04 Deceleration rate
0.05 Reference selector (do not adjust)
0.06 Current limit
0.07 Voltage mode selector
0.08 Boost voltage
0.09 Dynamic V/f select
0.10 Estimated motor speed [M]
Pr Function User
value
0.31 Macro number [M]
0.32 Serial comms. mode
0.33 Drive rated current (FLC) [M]
0.34 User security code [M]
0.35 Keypad reference [M]
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.38 Initial parameter displayed
0.39 Synchronize to a spinning motor
0.40 Autotune
0.41 PWM switching frequency selector
0.42 Motor – number of poles
0.43 Motor – power factor
0.44 Motor – rated voltage
0.45 Motor – rated speed
0.46 Motor – rated current
0.47 Motor – rated frequency
0.48 Drive software build number [M]
0.49 Security status [M]
0.50 Drive software version [M]
[M] indicates the parameter is for monitoring only
For descriptions of these parameters, see
Appendix D Menu 0 Parameters.
Pr Function User
value
0.11 Pre-ramp reference [M]
0.12 Post-ramp reference [M]
0.13 Motor active-current [M]
0.14 Jog reference (not used)
0.15 Braking mode selector
0.16 Stop mode selector
0.17 Status relay invert
0.18 S-ramp enable
0.19 S-ramp da/dt
0.20 Skip frequency 1
0.21 Skip band 1
0.22 Skip frequency 2
0.23 Skip band 2
0.24 Analog input 1 mode selector
0.25 Analog input 1 (torque reference)
0.26 Analog input 2 mode selector
0.27 Analog input 2 (frequency reference)
0.28 Over-speed threshold
0.29 Analog input 1 scaling
0.30 Analog input 2 scaling
3-30 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 59
Setting up and using Macro 4
Setting
Stnd.Ct
rP
Torque control
1. By default, the Drive operates in frequency
control. To disable this and enable torque
control, close the TORQUE ENABLE contact
(terminal 29).
2. Set 0.02 Frequency over-ride at the required
value to limit the maximum speed of the motor.
Refer to the following parameters in Appendix D
Menu 0 Parameters for selecting the required mode:
Analog
input
1 5, 6
27
Terminal(s) Parameter
0.24
Analog input 1 mode selector
0.26
Analog input 2 mode selector
Torque slaving
3. Set the analog torque reference at the
required level.
4. If required, adjust 0.29 Analog input 1 scaling to
change the scaling of the torque reference
input (see Torque slaving below).
5. If required, adjust 0.30 Analog input 2 scaling to
change the scaling of the frequency reference
input.
6. Set 0.28 Over-speed threshold at the frequency
that the Drive is to trip for protecting the
system.
Default value: ([0.02] x 1.2) Hz
Range: 0 ~ ([1.06] x 1.2) Hz
7. Monitor the torque reference by displaying
parameter 0.25 Analog input 1.
Reference selection
For correct operation of this macro configuration,
the setting of parameter 0.05 Reference selection
should be at 0.
Jog frequency
There is no need to adjust 0.14 Jog reference since
the jog function cannot be used.
1. Set up a master Drive in Macro 0 with
frequency control.
2. Set up slave Drive(s) in Macro 4.
3. Make connections between the Drives as shown
in Figure 3–12.
Master Drive Slave Drive
Signal
connector
(part)
Signal
connector
(part)
Figure 3–12 Torque slaving connections
4. If the slave Drive(s) is to deliver a different
torque from that of the master Drive, for
(each) slave Drive, adjust 0.29 Analog input 1
scaling accordingly.
Stopping and braking modes
Refer to the following parameters in Appendix D
Menu 0 Parameters:
Analog input modes
The analog inputs can be configured for the
following input signals:
0 ~ 20mA, 4 ~ 20mA or 0 ~ 10V
Commander GP User Guide
Issue code: gpxu2
Parameter
0.150.15
Ramp mode selector
0.160.16
Stop mode selector
Setting Up the Drive 3-31
Function
(Standard controlled)
Deceleration time is
extended if the
voltage reaches its
maximum permissible
value during braking.
Ramp to stop then the
Drive is disabled
DC-bus
Page 60
Use this free space for notes
3-32 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 61
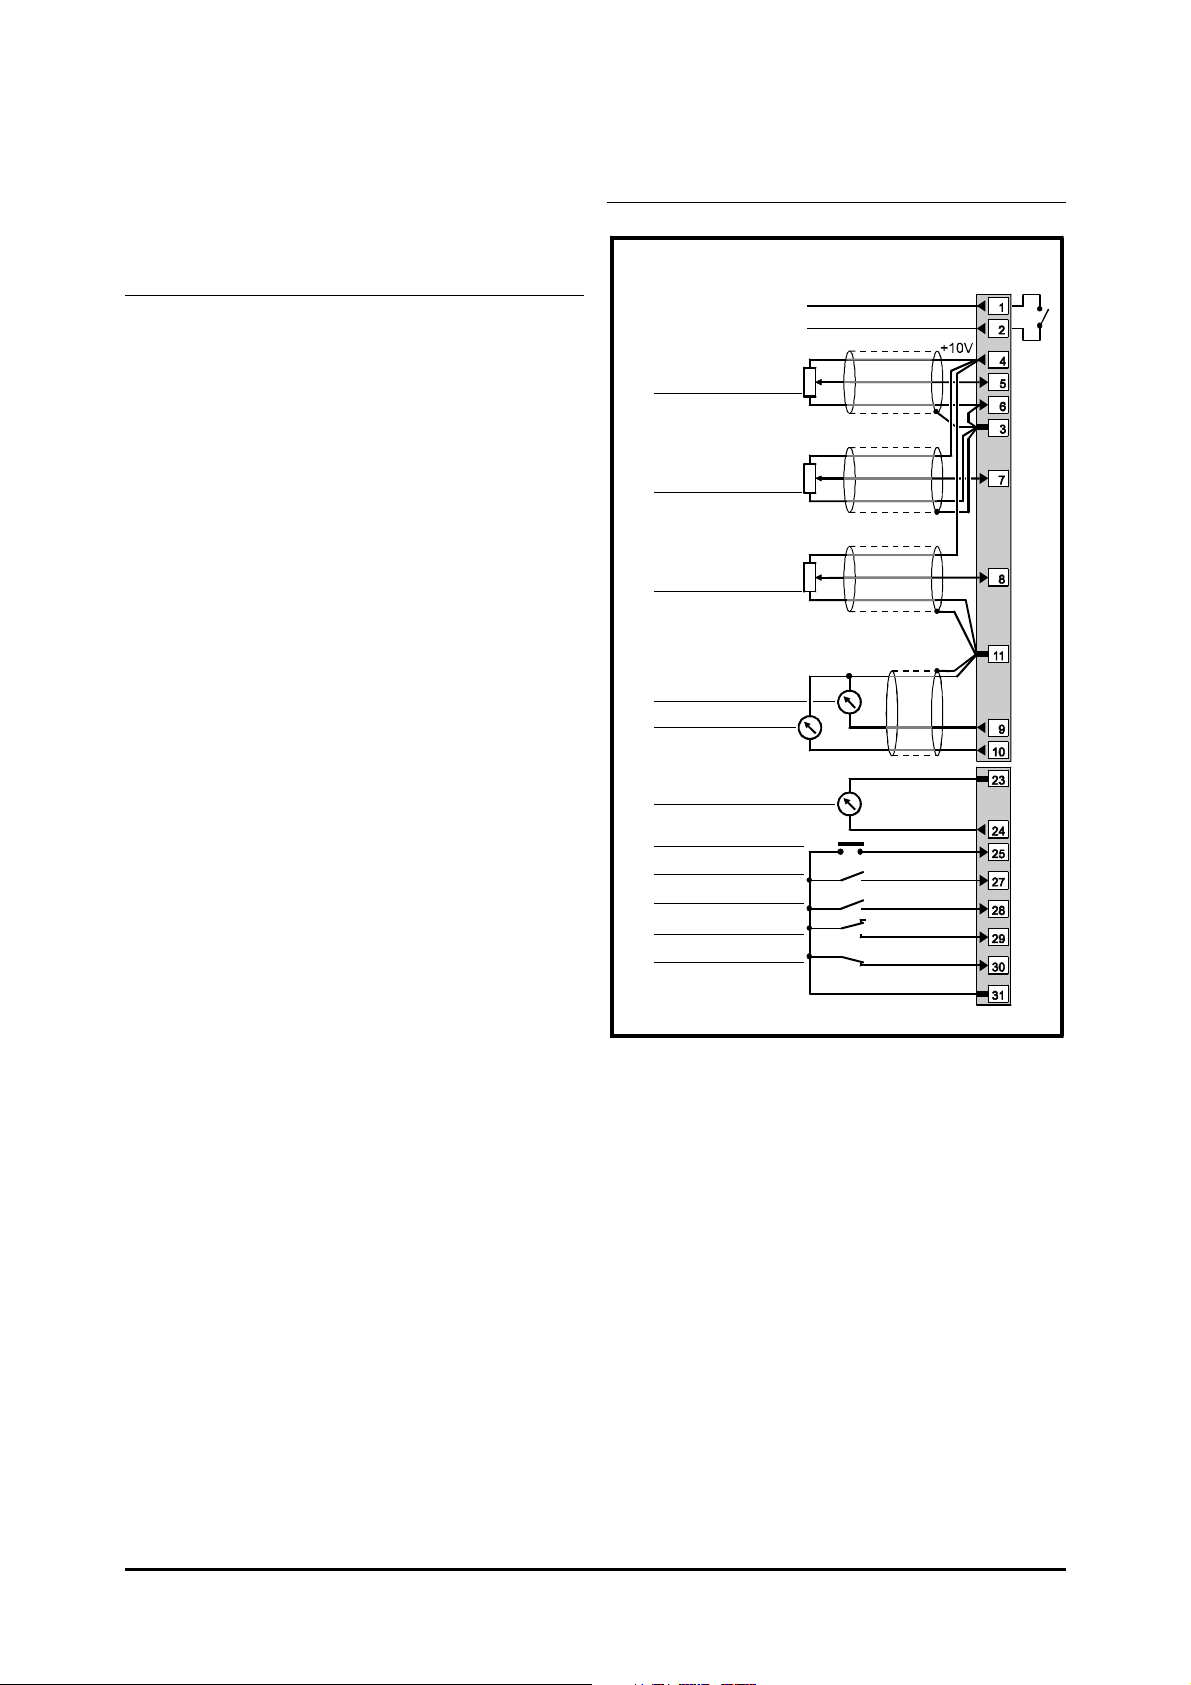
3.8 Macro 5
PID (set-point control)
Features
Specific features
Signal connections for Macro 5
Status relay
Drive healthy
Signal
connector
PID control is used for applications where a process
is required to be maintained at a set-point. Typical
applications are as follows:
• Closed-loop tension-control processes
where a dancer-arm is used
• Closed-loop pressure-control systems
Selection can be made between PID and analog
frequency control. When PID control is selected,
the three analog inputs are configured as follows:
• Frequency reference to define the frequency
demand
• PID feedback from the feedback device
• PID reference to define the set-point
The dynamic performance, scaling and range of the
PID control can be adjusted.
Two preset references and an optional software
PID-enable can be used.
Standard features
• Macro 5 operates in Terminal mode only
• Digital control by RUN FORWARD and
RUN REVERSE contacts
• Analog frequency inputs
• Adjustment of acceleration and deceleration
ramps
• Negative logic for the digital inputs
• SPEED and TORQUE analog outputs
• AT SPEED digital output
• External trip digital input
• Drive RESET digital input
Frequency
reference 1 (0 ~ 10V)
0V common
PID reference
(0 ~ 10V)
PID feedback
0V common
SPEED
TORQUE
AT SPEED
RESET
RUN FORWARD
RUN REVERSE
PID ENABLE
External trip
0V common
FREQUENCY CONTROL
PID CONTROL
0V common
Figure 3–13 Control signal connections
for Macro 5
For electrical specifications, refer to Appendix C
Signal Connections.
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-33
Page 62
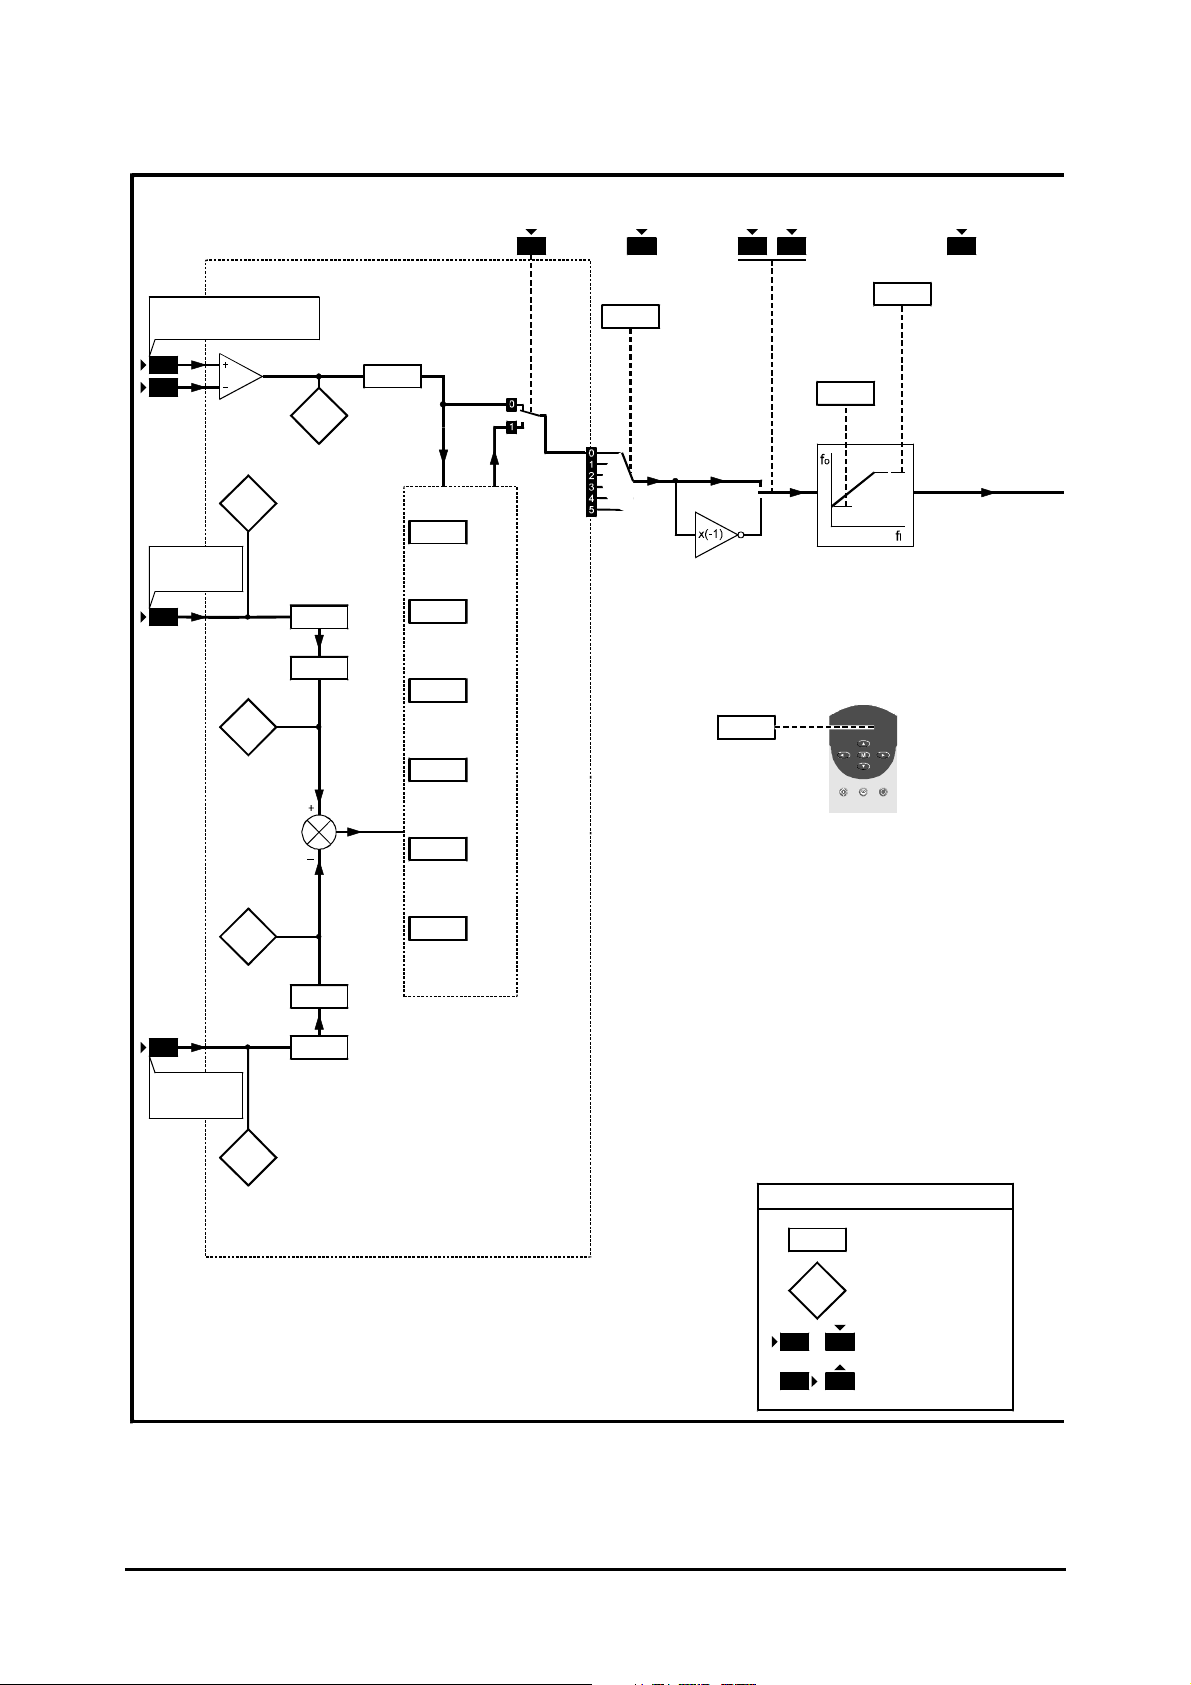
Reference selection
Frequency reference
5
6
Analog
input 2
0.18
PID
reference
7
Analog
input 2
scaling
0.26
Post-scaling
PID reference
0.17
Analog
input 1
Analog input 2
mode
selector
0.15
0.28
Analog
input 1
mode
selector
0.14
PID output high
limit
PID
0.20
PID proportional
gain
0.21
PID integral
gain
0.22
PID derivative
gain
0.23
PID
ENABLE
29
RESET
25 30
Reference
selector
0.05
RUN
FORWARD
27 28
0.38
Initial
parameter
displayed
RUN
REVERSE
Minimum
frequency
0.01
EXTERNAL TRIP
Maximum
0.02
frequency
0.24
Post-scaling
PID feedback
0.27
Analog
input 3
scaling
8
PID
feedback
0.19
Analog
input 3
The parameters are shown at their default settings.
The logic diagram is valid when all parameters are
at their default settings but may not be valid when
certain parameters are adjusted.
0.29
0.16
Analog input 3
selector
mode
PID output
low limit
0.25
PID output
scale factor
Figure 3–14 Programmable software for Macro 5
0.XX
0.XX
X X
X X
Key
Read-write (RW)
parameter
Read-only (RO)
parameter
Input terminals
Output terminals
3-34 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 63
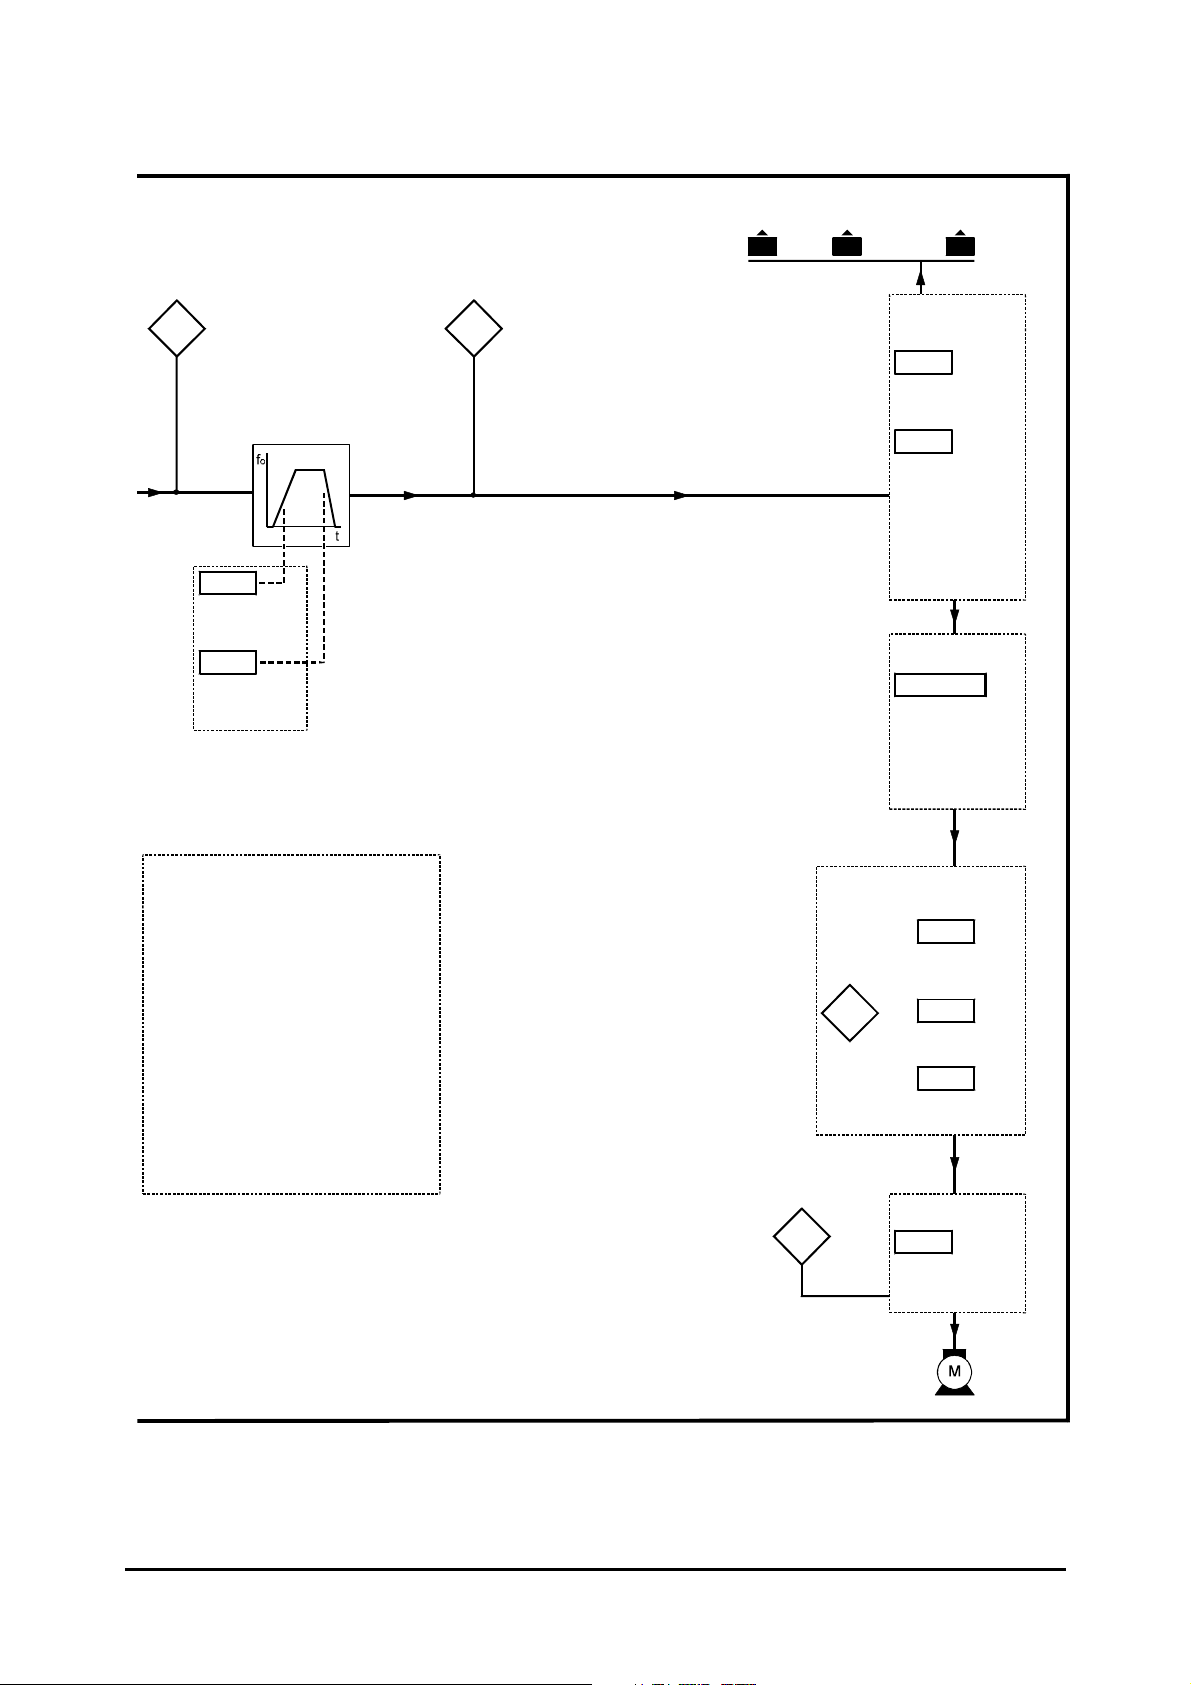
Pre-ramp
reference
0.11 0.12
Ramps
0.03
Acceleration
rate
0.04
Deceleration
rate
Post-ramp
reference
SPEED
9 10 24
TORQUE
Motor control
0.06
Current
limit
0.39
Synchronize
to a spinning
motor
Motor parameters
0.42 ~ 0.47
No. of poles
Power factor
Rated voltage
Rated speed
Rated current
Rated frequency
AT SPEED
Other parameters
0.31 Macro number
0.32 Serial comms. mode
0.33 Drive rated current
0.34 User security code
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.40 Autotune
0.48 Drive software build number
0.49 Security status
0.50 Software version number
0.10
Estimated
motor
speed
Motor
active-current
0.13
Motor-voltage control
0.07
Voltage mode
selector
0.08
Boost voltage
0.09
Dynamic V/f
select
Power stage
0.41
PWM switching
frequency
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-35
Page 64
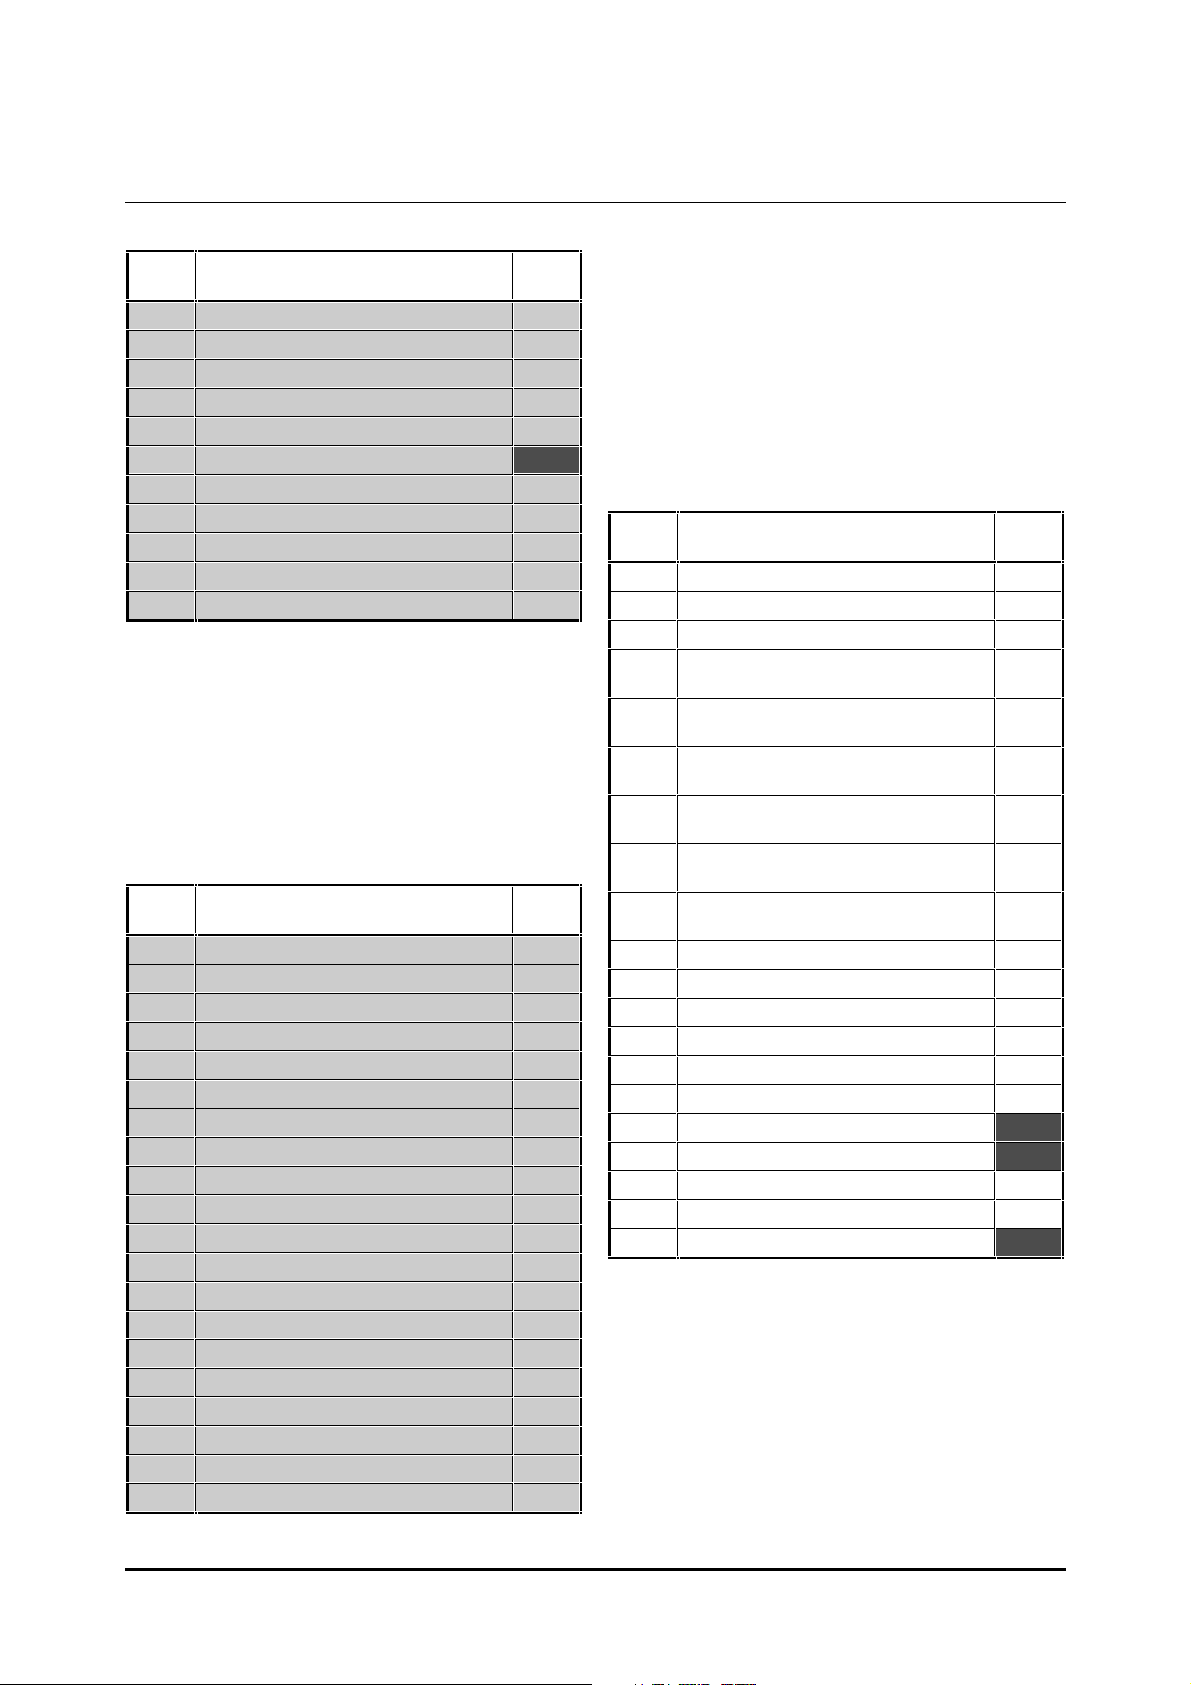
List of parameters specific to Macro 5
Pr Function User
value
0.00 Configuration and saving
0.01 Minimum frequency
0.02 Maximum frequency
0.03 Acceleration rate
0.04 Deceleration rate
0.05 Reference selector (do not adjust)
0.06 Current limit
0.07 Voltage mode selector
0.08 Boost voltage
0.09 Dynamic V/f select
0.10 Estimated motor speed [M]
Pr Function User
value
0.31 Macro number [M]
0.32 Serial comms. mode
0.33 Drive rated current (FLC) [M]
0.34 User security code [M]
0.35 Keypad reference [M]
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.38 Initial parameter displayed
0.39 Synchronize to a spinning motor
0.40 Autotune
0.41 PWM switching frequency selector
0.42 Motor – number of poles
0.43 Motor – power factor
0.44 Motor – rated voltage
0.45 Motor – rated speed
0.46 Motor – rated current
0.47 Motor – rated frequency
0.48 Drive software build number [M]
0.49 Security status [M]
0.50 Drive software version [M]
[M] indicates the parameter is for monitoring only
For descriptions of these parameters, see
Appendix D Menu 0 Parameters.
Pr Function User
value
0.11 Pre-ramp reference [M]
0.12 Post-ramp reference [M]
0.13 Motor active-current [M]
0.14 Analog input 1 (frequency reference)
mode selector
0.15 Analog input 2 (PID reference) mode
selector
0.16 Analog input 3 (PID feedback) mode
selector
0.17 Analog input 1
(frequency reference)
0.18 Analog input 2
(PID reference)
0.19 Analog input 3
(PID feedback)
0.20 PID proportional gain
0.21 PID integral gain
0.22 PID derivative gain
0.23 PID output high limit
0.24 PID output low limit
0.25 PID output scale factor
0.26 Post-scaling PID reference
0.27 Post-scaling PID feedback
0.28 Analog input 2 scaling
0.29 Analog input 3 scaling
0.30 (Not used)
3-36 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 65
Setting up and using Macro 5
Setting up PID control
1. By default, the Drive operates in frequency
control. To disable this and enable PID control,
close the PID ENABLE contact (terminal 29).
2. Set the PID REFERENCE potentiometer
(terminal 7) at the required set-point.
3. Set the FREQUENCY REFERENCE (terminals
5, 6) for the required nominal motor (process)
speed.
4. Connect the feedback device to terminal 8
(PID FEEDBACK).
5. The values of the analog signals can be
monitored by displaying the following
parameters:
0.17 Frequency reference
0.18 PID reference
0.19 PID feedback
0.26 Post-scaling PID reference
0.27 Post-scaling PID feedback
Adjusting the PID control range
In PID control, the PID reference and PID feedback
are each passed through a scaling stage, and the
error resulting from differences between these
references is passed through a limiter and then
through a final scaling stage.
The limiter is used for applying minimum and
maximum limits to the PID error. The minimum
error can be a negative value.
The final scaling stage is used for adjusting the
degree of change to the frequency reference.
After these two stages, the error is added to the
frequency reference.
1. The default scaling for analog inputs 2 and 3
is 1. If required, adjust the following
parameters to alter the scaling:
0.28 Analog input 2 scaling (PID reference)
0.29 Analog input 3 scaling (PID feedback)
3. To define the minimum value of PID error, set
0.24 PID low limit at the required value.
Default value: –100 %
Range: ±100 %
4. To define the degree of control on the
frequency reference, set 0.25 PID output scale
factor at the required value.
Default value: 1
Range: 0 ~ 4.000
Adjusting the PID gain settings
The following parameters are used:
0.20 PID proportional gain
Default value: 1
Range: 0 ~ 4.000
0.21 PID integral gain
Default value: 0.5
Range: 0 ~ 4.000
0.22 PID derivative gain
Default value: 0
Range: 0 ~ 4.000
Reference selection
For correct operation of this macro configuration,
the setting of parameter of 0.05 Reference selection
should be at 0.
Analog input modes
The analog inputs can be configured for the
following input signals:
0 ~ 20mA, 4 ~ 20mA or 0 ~ 10V
Refer to the following parameters in Appendix D
Menu 0 Parameters for selecting the required mode:
Analog
input
1 5, 6
27
38
Terminal(s) Parameter
0.14
Analog input 1 mode selector
0.15
Analog input 2 mode selector
0.16
Analog input 3 mode selector
2. To limit the maximum value of PID error, set
0.23 PID high limit at the required value.
Default value: 100 %
Range: 0 ~ 100 %
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-37
Page 66
3.9 Macro 6
Axis-limit control
Features
Specific features
Axis-limit control is used for applications which
require the process to be automatically stopped
when a position limit has been reached.
Speed can be controlled in both directions in either
of two ways, as follows:
• Bipolar frequency reference signal and use
of a RUN FORWARD contact (bipolar
control)
• Unipolar frequency reference signal and use
of RUN FORWARD and RUN REVERSE
contacts (unipolar control)
Selection can be made between the following
frequency reference inputs:
Local unipolar input (0 ~ 10V)
Remote differential input which can be used
as follows:
• Single-ended unipolar input (0 ~ 10V)
• Single-ended bipolar input (±10V)
• Bipolar or unipolar differential input (±10V
on each line)
Travel in each direction is halted by use of a LIMIT
digital input. By default, these inputs require
normally-open contacts but can be configured for
normally-closed contacts.
Standard features
• Macro 6 operates in Terminal mode only
• Adjustment of minimum and maximum
frequencies
• Adjustment of acceleration and
deceleration ramps
• Selection of stopping modes
• Motor thermistor input
• SPEED and TORQUE analog outputs
• AT SPEED digital output
• External tripdigital input
• Drive RESET digital input
To run the Drive, the appropriate RUN contact must
be closed. When the related LIMIT contact changes
state to mark the axis limit, the Drive decelerates to
zero speed at a rate set by the user. In order to
change direction, it is necessary to perform either of
the following, as appropriate:
• Bipolar control: Reverse the polarity of the
frequency reference
• Unipolar control: Open the RUN switch, and
then close the RUN switch for the opposite
direction
The Drive is operated under frequency control.
Selection can be made to apply torque to the motor
at zero speed, or to allow the motor to rotate
freely.
3-38 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 67
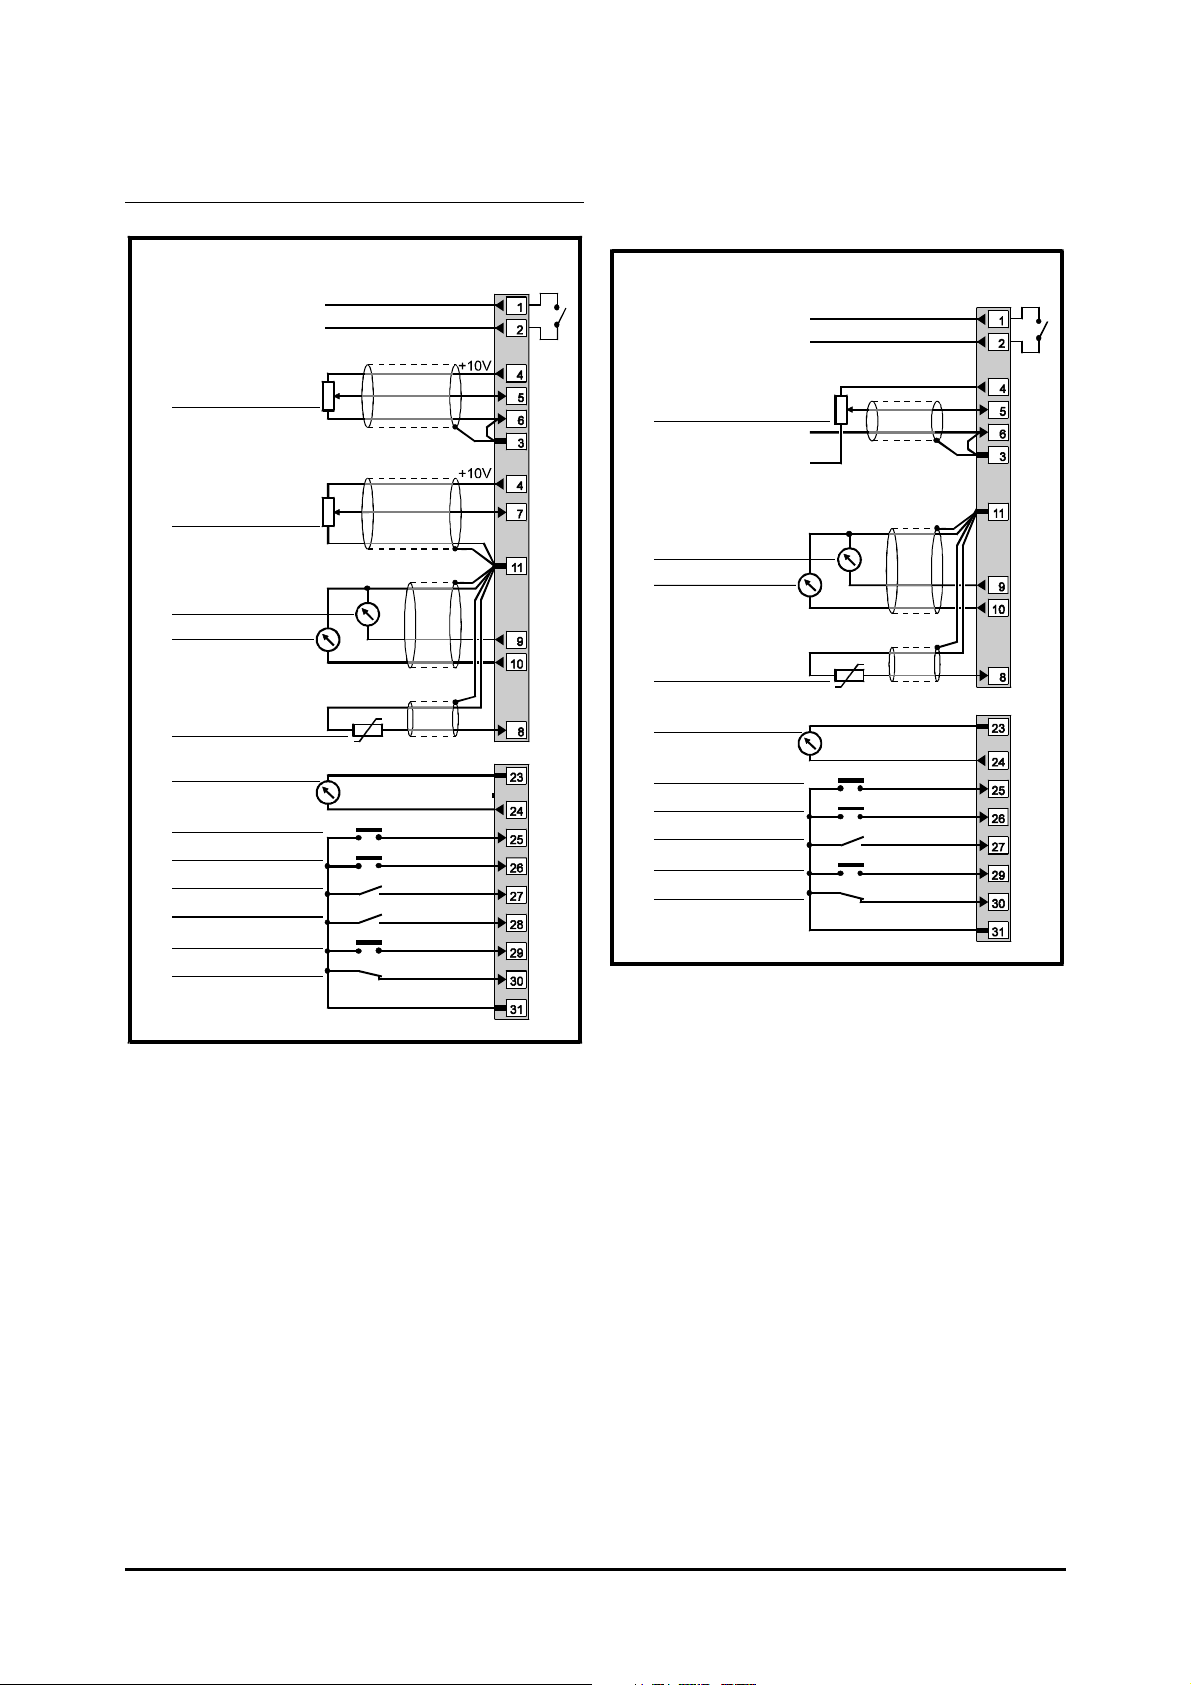
Signal connections for Macro 6
Signal
connector
Status relay
Drive healthy
Analog
frequency/speed
reference 1
(remote) 0 ~ 10V
Analog
frequency/speed
reference 2
(local) 0 ~ 10V
SPEED
TORQUE
Motor thermistor
AT SPEED
RESET
LIMIT FORWARD
RUN FORWARD
RUN REVERSE
LIMIT REVERSE
External trip
0V common
0V common
0V common
Figure 3–14 Control signal and thermistor
connections for Macro 6 when
used in unipolar control
Signal
connector
Status relay
Drive healthy
Analog
frequency/speed
reference
±10V
SPEED
TORQUE
Motor thermistor
AT SPEED
RESET
LIMIT FORWARD
RUN
LIMIT REVERSE
External trip
0V
−10V
+10V
0V common
0V common
0V common
Figure 3–15 Control signal and thermistor
connections for Macro 6 when
used in bipolar control (typical
frequency reference
connections)
For electrical specifications, refer to Appendix C
Signal Connections.
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-39
Page 68
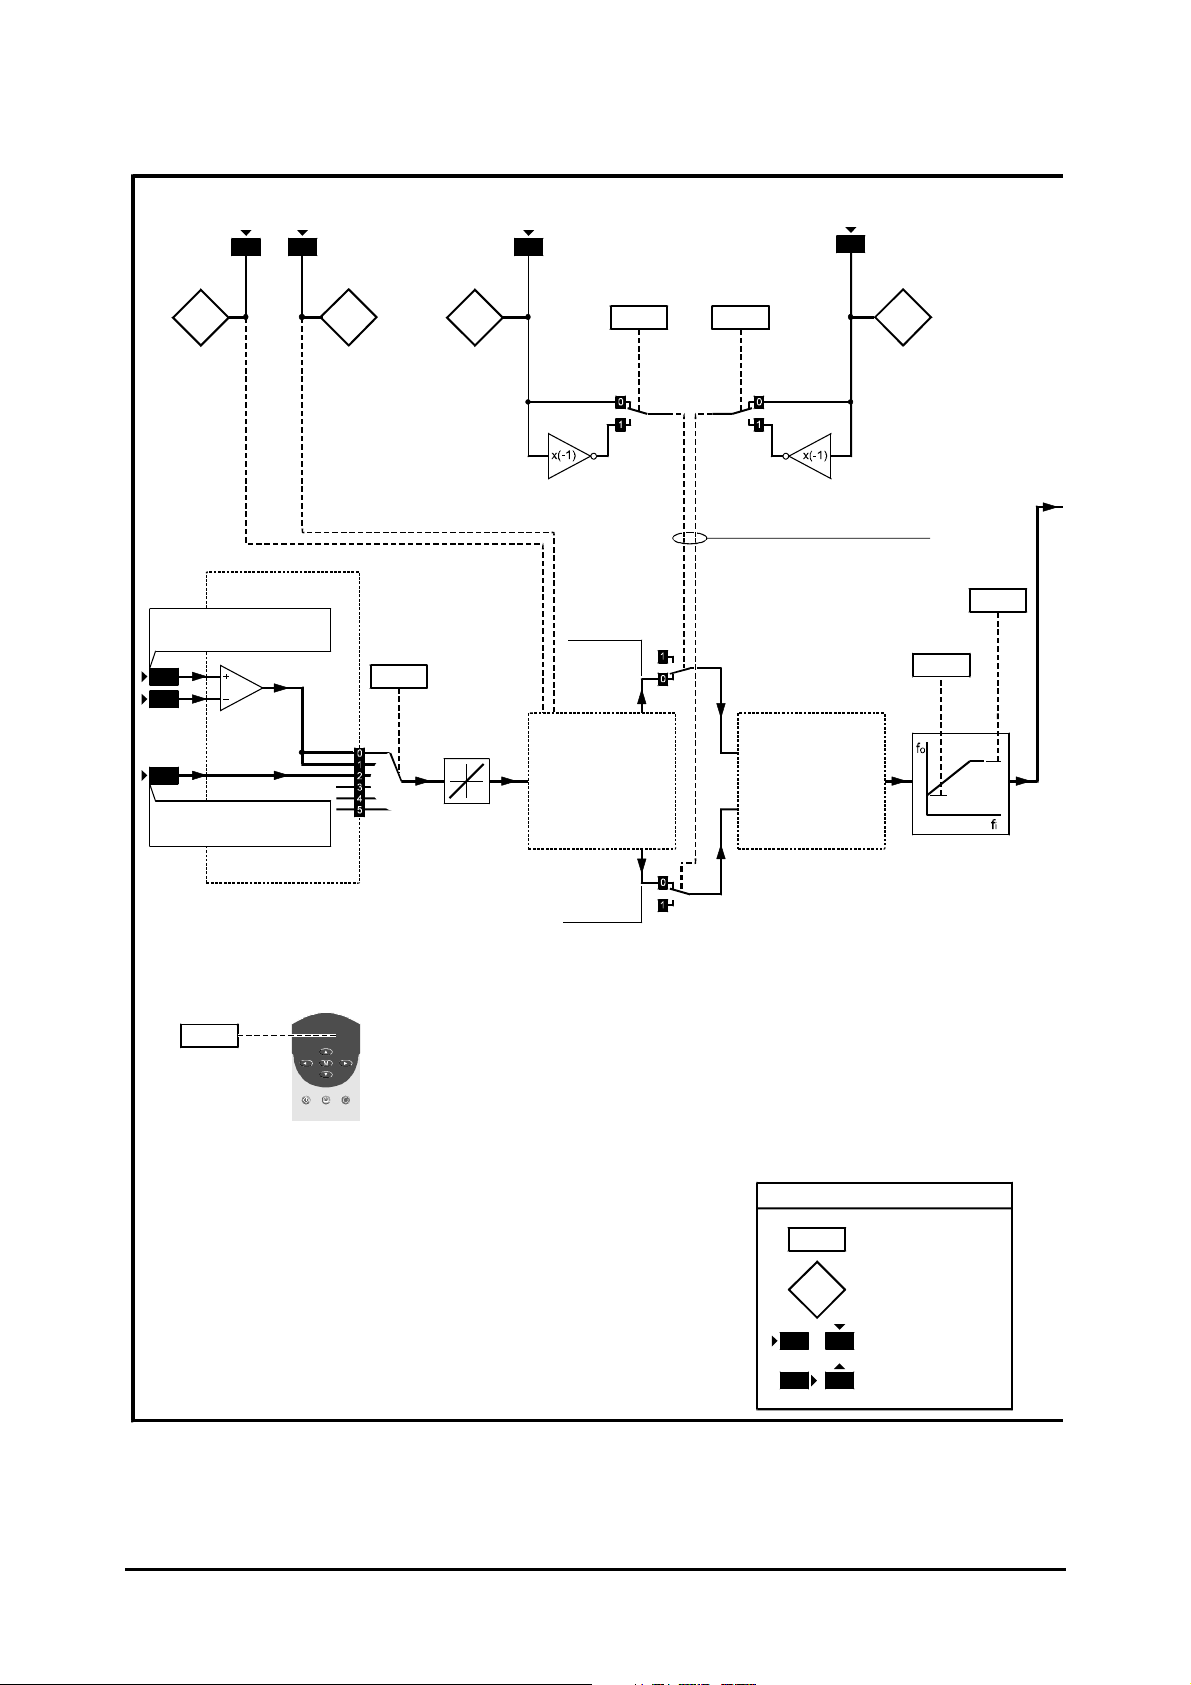
RUN
(FORWARD)
0.15
RUN
REVERSE
0.16 0.22
FORWARD
0.14
LIMIT
2627 28
Limit
forward
invert
0.21
Limit
reverse
invert
LIMIT
REVERSE
29
0.17
Run
forward
indicator
Reference selection
Frequency reference 1
(remote)
5
6
7
Frequency reference 2
(local)
Run
reverse
indicator
Reference
selector
0.05
Limit
forward
indicator
Forward
frequency
reference
Frequency
reference
Direction control
Reverse
frequency
reference
RUN enabled
0 =
RUN disabled (at limit)
1 =
Bi-directional
frequency
reference
Limit
reverse
indicator
Minimum
frequency
clamp
Maximum
frequency
clamp
0.01
0.02
0.38
Power up
parameter
display
setting
The parameters are shown at their default settings.
The logic diagram is valid when all parameters are
at their default settings but may not be valid when
certain parameters are adjusted.
Figure 3–16 Programmable software for Macro 6
3-40 Setting Up the Drive
0.XX
0.XX
X X
X X
Key
Read-write (RW)
parameter
Read-only (RO)
parameter
Input terminals
Output terminals
Commander GP User Guide
Issue code: gpxu2
Page 69
RESET FREQUENCY TORQUE
25 9 10 24
Pre-ramp
reference
0.11 0.12
Ramps
0.03
Acceleration
rate
0.20
OL>
Deceleration
rate
0.04
CL>
Deceleration
rate
EXTERNAL TRIP
Post-ramp
reference
AT SPEEDTHERMISTOR
830
Motor control
0.06
Current
limit
0.18
Stop mode
selector
0.19
Hold zero
speed
0.39
Synchronize
to a spinning
motor
Motor parameters
0.42 ~ 0.47
No. of poles
Power factor
Rated voltage
Rated speed
Rated current
Rated frequency
Other parameters
0.31 Macro number
0.32 Serial comms. mode
0.33 Drive rated current
0.34 User security code
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.40 Autotune
0.48 Drive operating mode
0.49 Security status
0.50 Software version number
selector
0.10
Estimated
motor
speed
Motor
active-current
0.13
Motor-voltage control
0.07
Voltage mode
selector
0.08
Boost voltage
0.09
Dynamic V/f
select
Power stage
0.41
PWM switching
frequency
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-41
Page 70
List of parameters specific to Macro 6
Pr Function User
value
0.00 Configuration and saving
0.01 Minimum frequency clamp
0.02 Maximum frequency clamp
0.03 Acceleration rate
0.04 Deceleration rate
0.05 Reference selector (limited settings)
0.06 Current limit
0.07 Voltage mode selector
0.08 Boost voltage
0.09 Dynamic V/f select
0.10 Estimated motor speed [M]
Pr Function User
value
0.31 Macro number [M]
0.32 Serial comms. mode
0.33 Drive rated current (FLC) [M]
0.34 User security code [M]
0.35 Keypad reference [M]
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.38 Power up parameter display select
0.39 Synchronize to a spinning motor
0.40 Autotune
0.41 PWM switching frequency selector
0.42 Motor – number of poles
0.43 Motor – power factor
0.44 Motor – rated voltage
0.45 Motor – rated full load RPM
0.46 Motor – rated current
0.47 Motor – rated frequency
0.48 Drive operating mode selector
0.49 Security status [M]
0.50 Drive software version [M]
[M] indicates the parameter is for monitoring only
For descriptions of these parameters, see
Appendix D Menu 0 Parameters.
Pr Function User
value
0.11 Pre-ramp reference [M]
0.12 Post-ramp reference [M]
0.13 Motor active-current [M]
0.14 Limit forward indicator [M]
0.15 Run forward indicator [M]
0.16 Run reverse indicator [M]
0.17 Limit reverse indicator [M]
0.18 Stop mode selector
0.19 Hold zero speed enable
0.20 Limit deceleration rate
0.21 Limit forward invert
0.22 Limit reverse invert
0.23 (Not used)
0.24 (Not used)
0.25 (Not used)
0.26 (Not used)
0.27 (Not used)
0.28 (Not used)
0.29 (Not used)
0.30 (Not used)
3-42 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 71
Setting up and using Macro 6
Deceleration rates
The following may require attention in addition to
the settings made in Chapter 2.
Frequency control
When Macro 6 is selected, the Drive always operates
in axis-limit control; unlike Macros 2 to 5, no digital
input exists to allow switching to and from normal
frequency control.
Operation in bipolar or unipolar frequency control is
dependent only on the signal connections made.
When bipolar control is required, to prevent
confusion do not connect a RUN REVERSE contact.
No jog function exists.
Reference selection
Use 0.05 Reference selector to select the required
frequency reference source, as follows:
0.05 Source Terminal(s)
0 Analog input 1 (bipolar or unipolar) 5, 6
1 Analog input 1 (bipolar or unipolar) 5, 6
2 Analog input 2 (unipolar only) 7
3 (Do not use)
4 (Do not use)
5 (Do not use)
Analog input mode
The analog inputs are configured for 0 ~ 10V.
See the Commander Gp Advanced User Guide for
selecting other modes.
Limit switch types
By default, the Drive requires normally-open limit
switches. When either or both limit switches are to
be normally-closed, set the following parameters
at 1, as appropriate:
LIMIT FORWARD 0.21
LIMIT REVERSE 0.22
Position the limit switches
to allow for the distance
Caution
The rate of deceleration to be applied when the
motor is being stopped at the limit of travel can be
adjusted separately from the normal deceleration
rate, as follows:
Use 0.04 Deceleration rate for adjusting the
maximum deceleration rate that is to apply when
any of the following occurs:
• The motor is stopped by removal of a RUN
command
• The motor is stopped or slowed by
reduction of the frequency reference
For setting the deceleration rate at the limit of
travel, use parameter 0.20 Limit deceleration rate.
that will be travelled during
deceleration. This distance
will be increased if the
deceleration time is
extended (see Braking mode).
Braking mode
The FASt ramp mode is applied. This gives
continuous deceleration under maximum braking
conditions (the ramp mode should not be changed).
A braking resistor is normally required in order to
prevent the
level.
DC-bus voltage from reaching the trip
Stopping modes
Refer to parameter 0.18 Stop mode selector in
Appendix D Menu 0 Parameters.
Hold zero speed
Refer to parameter 0.19 Hold zero speed enable in
Appendix D Menu 0 Parameters.
The default setting is 0 (Free to
rotate).
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-43
Page 72
Use this free space for notes
3-44 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 73
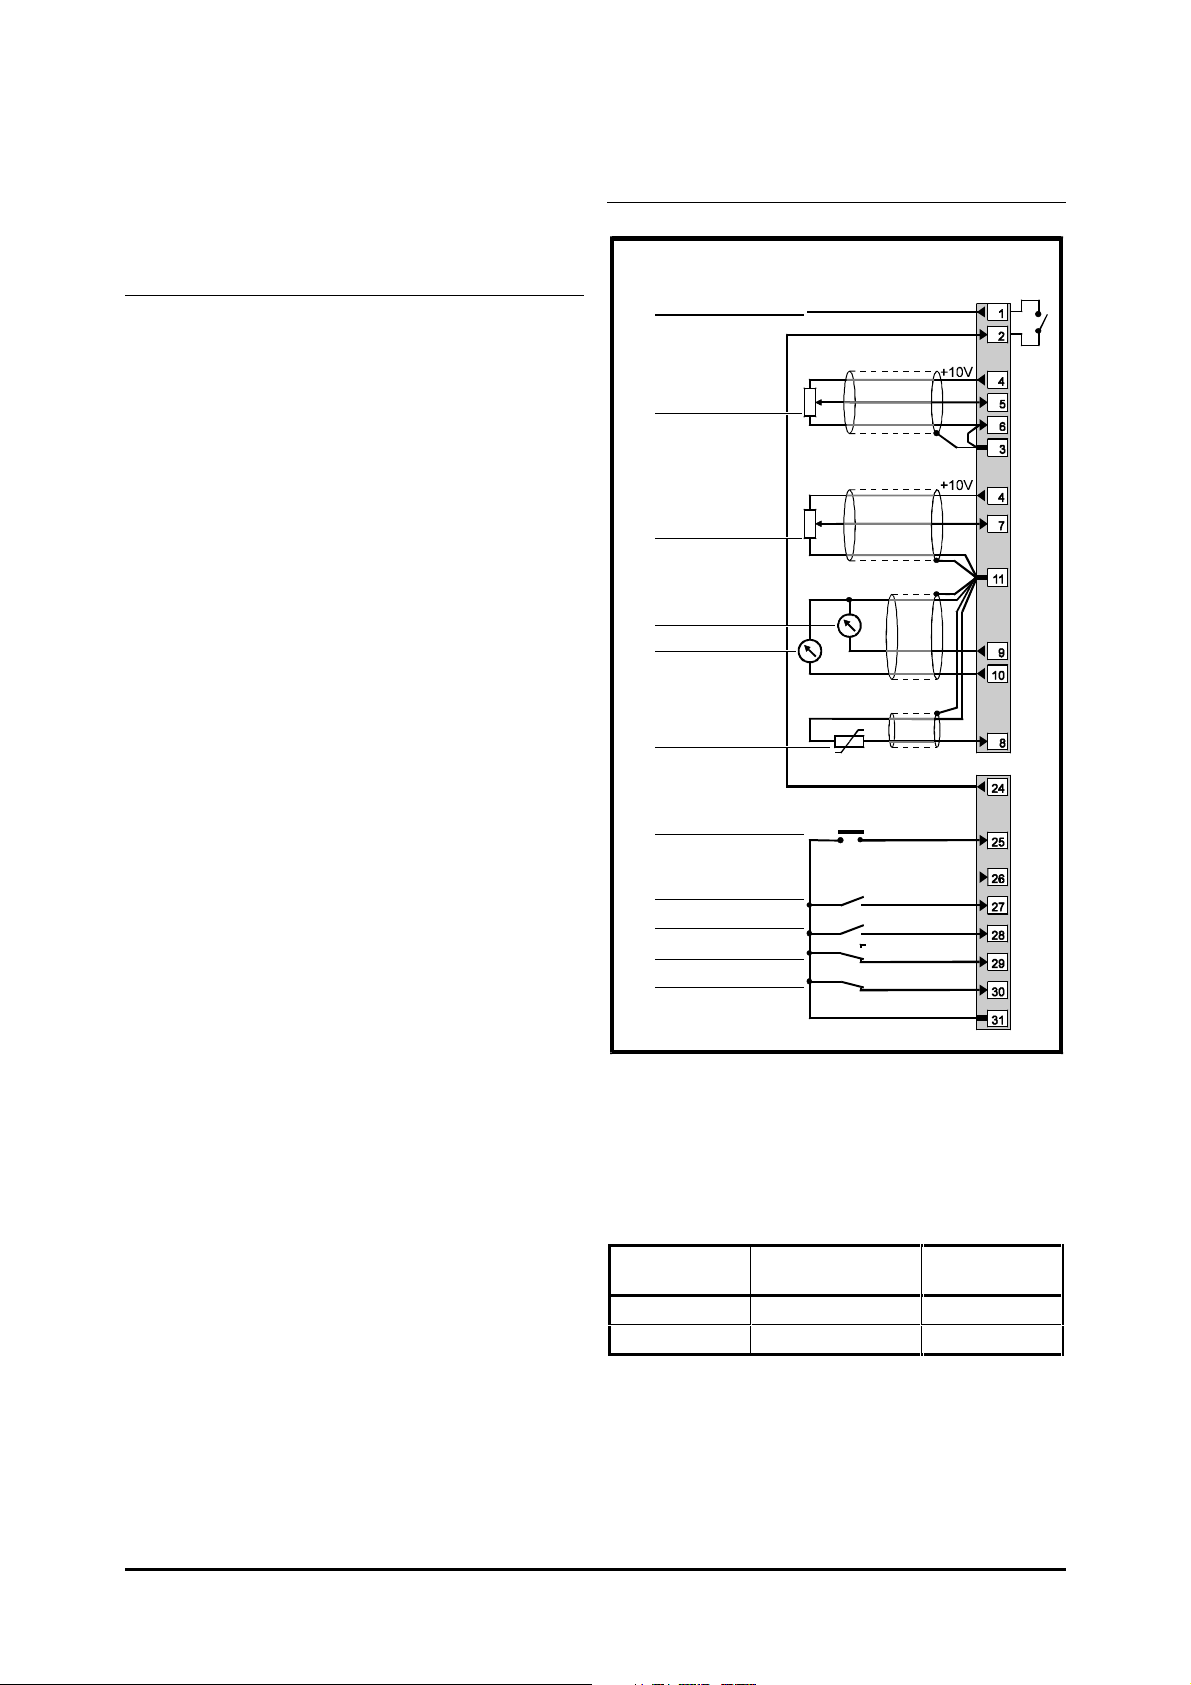
3.10 Macro 7
BRAKE RELEASE
logic state
1
0
Brake control
Features
Specific features
Signal connections for Macro 7
BRAKE RELEASE
Signal
connector
Brake control is used for controlling the application
and release of a mechanical brake in hoist or crane
applications. The Drive issues a brake release signal
when all of the following conditions are met:
• The Drive has not tripped (ie. healthy)
• The output frequency of the Drive is
above 1Hz
• Current above a user-defined threshold is
being supplied to the motor in order to hold
or move the load
The brake release signal can be delayed by an amount
that is adjusted by the user. This delay is used to
ensure that only genuine conditions will cause the
brake to be released.
The Drive applies the brake, by removing the brake
release signal, as the motor is stopping and motor
current falls below the threshold level.
The Drive is operated under frequency control;
selection can be made between local and remote
sources, as well as keypad control.
Standard features
• Macro 7 can be operated in Terminal mode
(default) or Keypad mode
• Digital control by RUN FORWARD, and
RUN REVERSE contacts
• Analog frequency inputs
• Adjustment of minimum and maximum
frequencies
• Adjustment of acceleration and
deceleration ramps
• Motor thermistor input
• SPEED and TORQUE analog outputs
• External trip digital input
• Drive RESET digital input
Analog frequency
reference 1
(remote) 0 ~ 10V
0V common
Analog frequency
reference 2
(local) 0 ~ 10V
0V common
SPEED
TORQUE
Motor thermistor
RESET
RUN FORWARD
RUN REVERSE
LOCAL / REMOTE
External trip
REMOTE
LOCAL
0V common
Figure 3–17 Control signal and thermistor
connections for Macro 7
The BRAKE RELEASE output must be connected as
shown in Figure 3–17. Note that the actual BRAKE
RELEASE output appears on terminal 24 which
operates as shown in the following table.
Terminal 24
Effect
Commander GP User Guide
Issue code: gpxu2
Low
High
Release brake
Apply brake
For electrical specifications, refer to Appendix C
Signal Connections.
Setting Up the Drive 3-45
Page 74
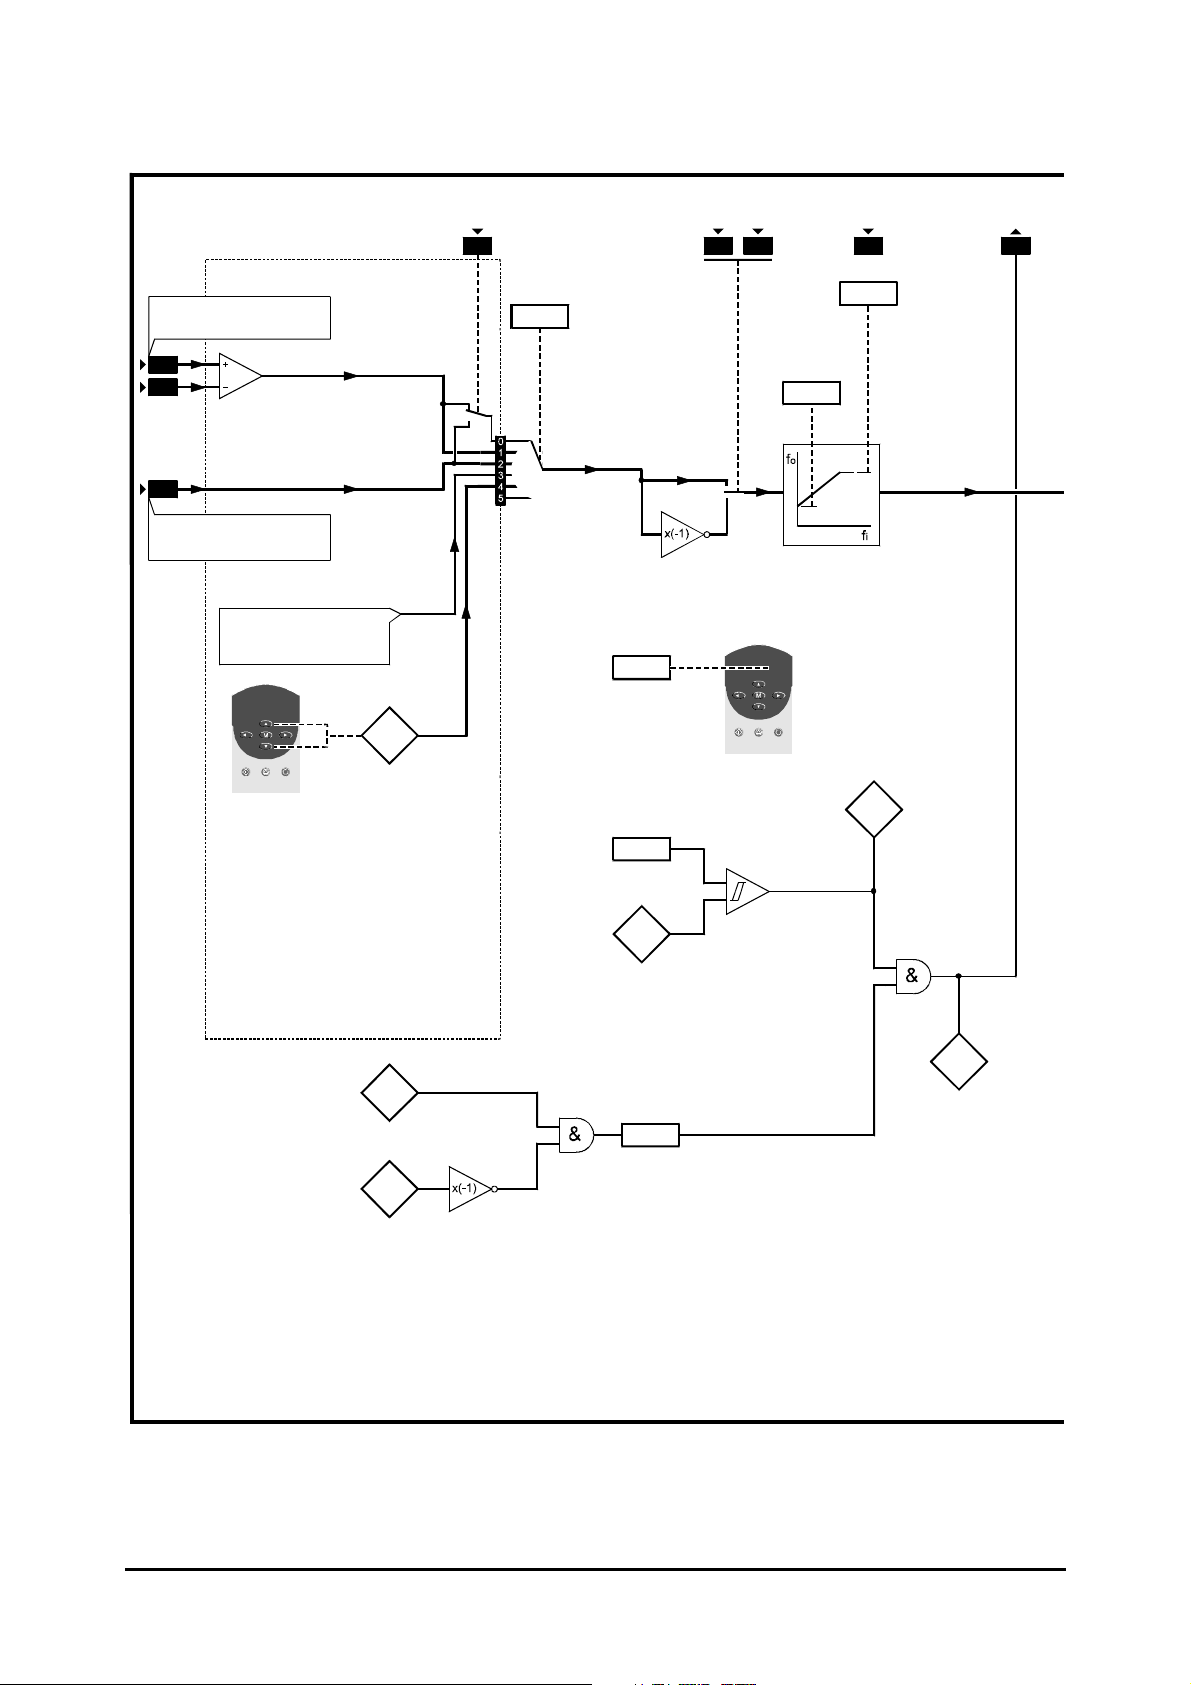
Reference selection
Frequency reference 1
(remote)
5
6
7
Frequency reference 2
(local)
Preset references
(see the
Commander Gp
Advanced User Guide
)
0.35
Keypad
reference
LOCAL /
REMOTE
29
Reference
selector
0.05
Current
threshold
FORWARD
0.38
Power up
parameter
display
setting
0.19
RUN
27 28
RUN
REVERSE
Minimum
frequency
clamp
0.01
RESET
25 24
Maximum
0.02
frequency
clamp
Current detected
indicator
0.15
RELEASE
BRAKE
Motor current
magnitude
Drive healthy
indicator
At zero speed
indicator
0.16
0.17
Figure 3–18 Programmable software for Macro 7
0.14
0.20
Brake
release
delay
0.18
Brake release
indicator
3-46 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 75
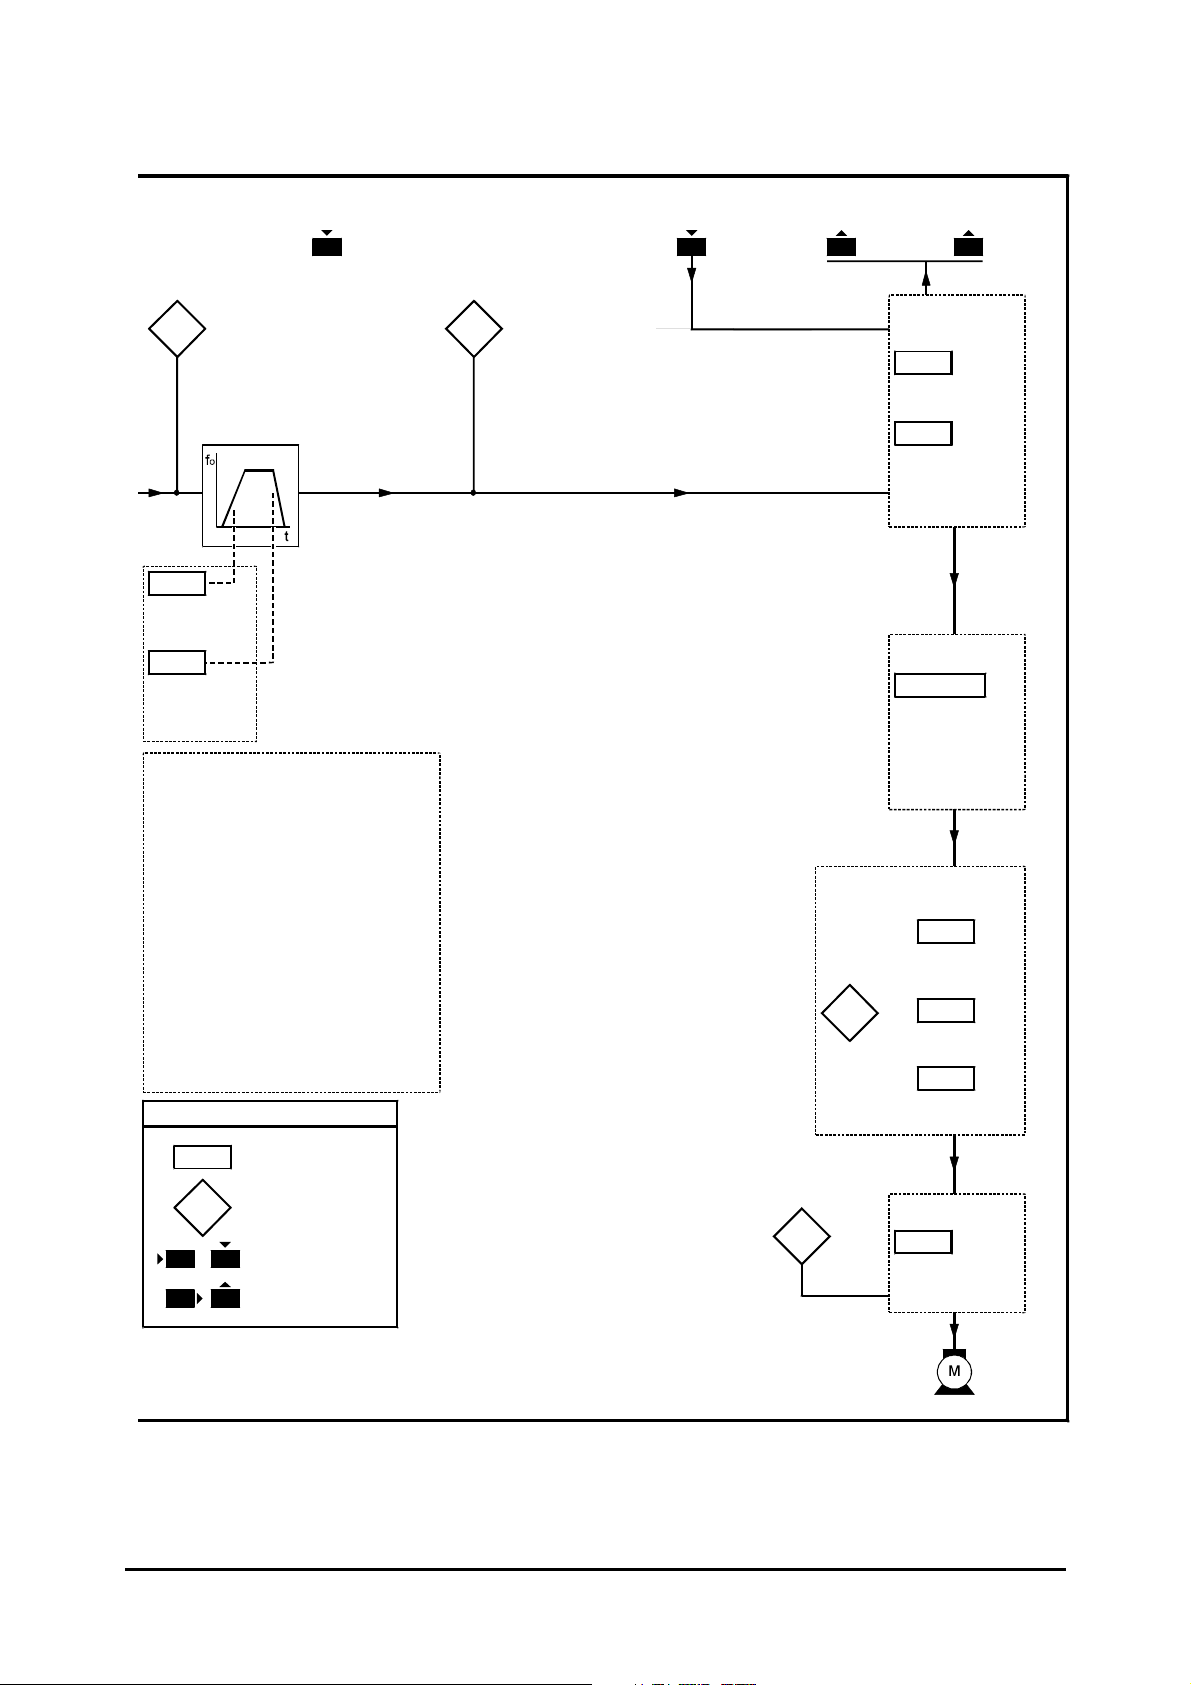
EXTERNAL TRIP
Pre-ramp
reference
0.11 0.12
Ramps
0.03
Acceleration
rate
0.04
Deceleration
rate
Other parameters
0.31 Macro number
0.32 Serial comms. mode
0.33 Drive rated current
0.34 User security code
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.40 Autotune
0.48 Drive operating mode
0.49 Security status
0.50 Software version number
Read-write (RW)
0.XX
parameter
Read-only (RO)
0.XX
parameter
X X
X X
Input terminals
Output terminals
selector
Key
Post-ramp
reference
THERMISTOR
830
FREQUENCY TORQUE
9 10
Motor control
0.06
Current
limit
0.39
Synchronize
to a spinning
motor
Motor parameters
0.42 ~ 0.47
No. of poles
Power factor
Rated voltage
Rated speed
Rated current
Rated frequency
Motor-voltage control
0.07
Voltage mode
selector
0.10
Estimated
motor
speed
Motor
active-current
0.13
0.08
Boost voltage
0.09
Dynamic V/f
select
Power stage
0.41
PWM switching
frequency
The parameters are shown at their default settings.
The logic diagram is valid when all parameters are
at their default settings but may not be valid when
certain parameters are adjusted.
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-47
Page 76
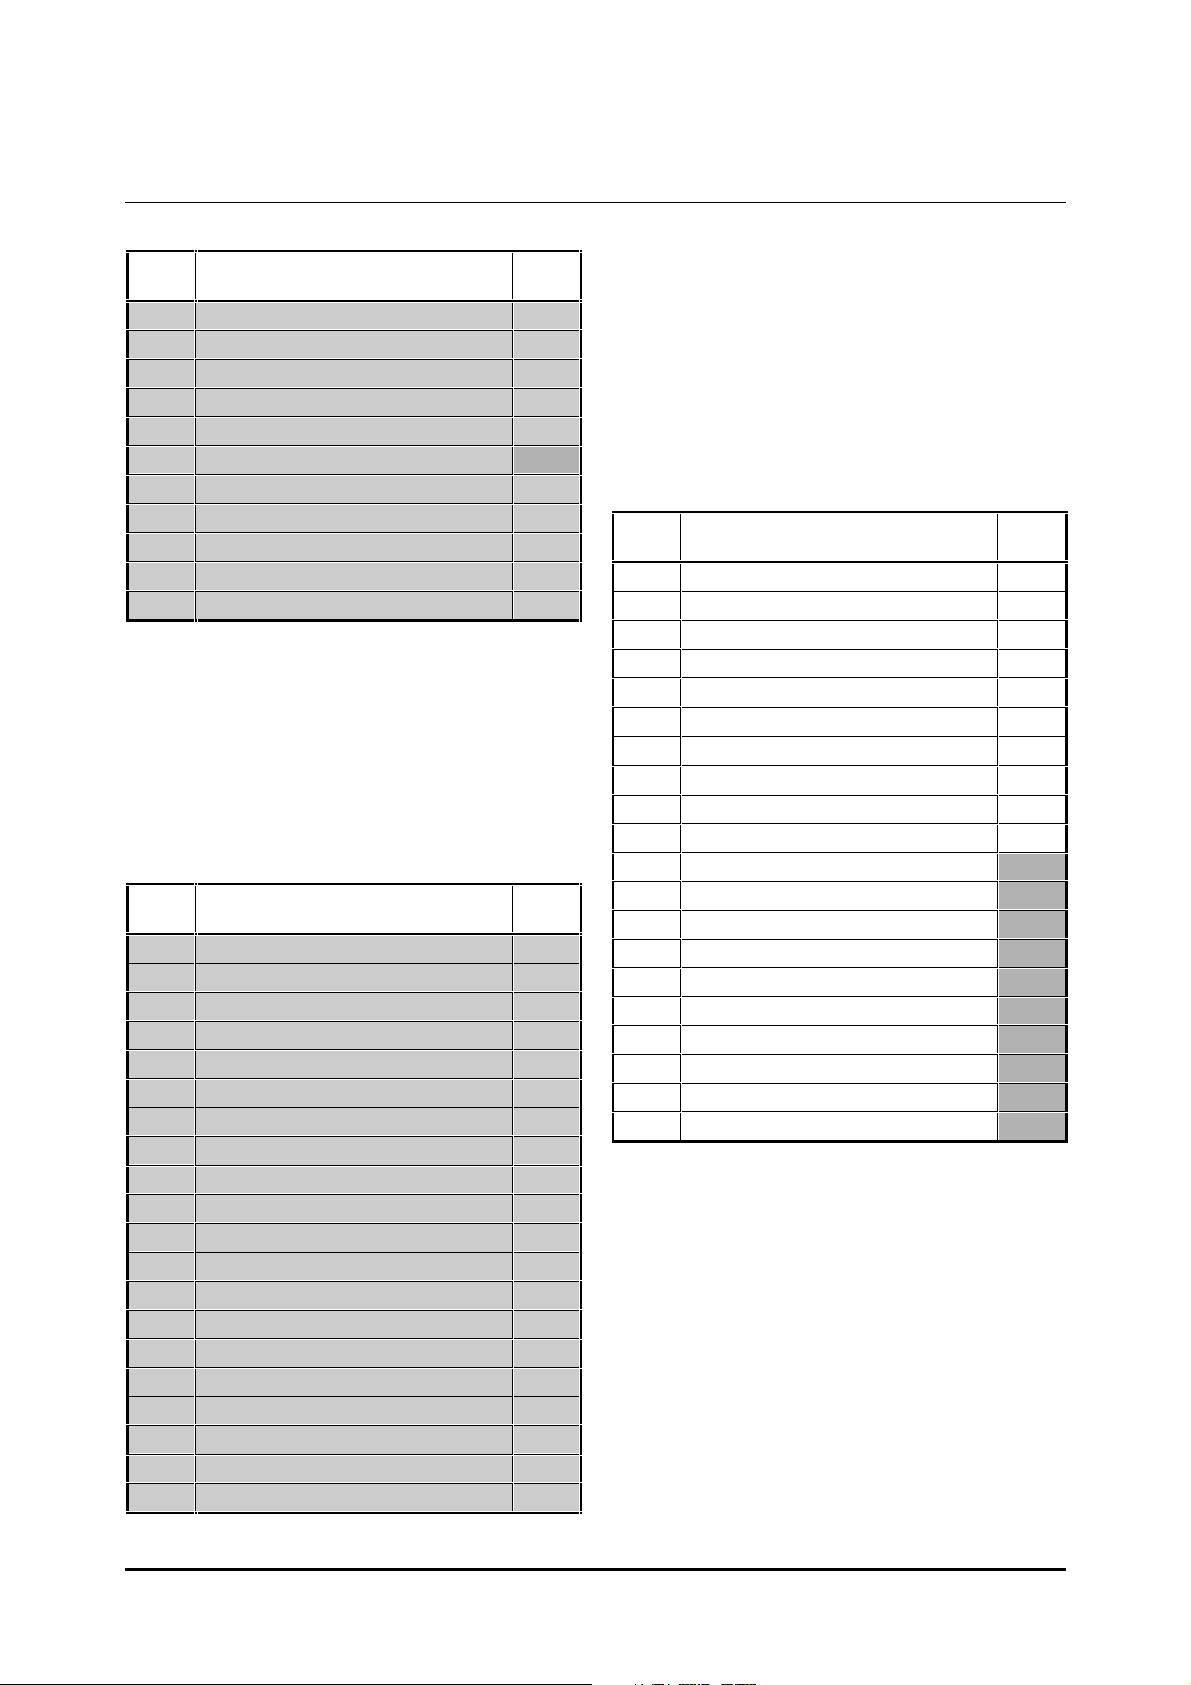
List of parameters specific to Macro 7
Pr Function User
value
0.00 Configuration and saving
0.01 Minimum frequency clamp
0.02 Maximum frequency clamp
0.03 Acceleration rate
0.04 Deceleration rate
0.05 Reference selector (limited settings)
0.06 Current limit
0.07 Voltage mode selector
0.08 Boost voltage
0.09 Dynamic V/f select
0.10 Estimated motor speed [M]
Pr Function User
value
0.31 Macro number [M]
0.32 Serial comms. mode
0.33 Drive rated current (FLC) [M]
0.34 User security code [M]
0.35 Keypad reference [M]
0.36 Serial comms. baud rate
0.37 Serial comms. address
0.38 Power up parameter display select
0.39 Synchronize to a spinning motor
0.40 Autotune
0.41 PWM switching frequency selector
0.42 Motor – number of poles
0.43 Motor – power factor
0.44 Motor – rated voltage
0.45 Motor – rated full load RPM
0.46 Motor – rated current
0.47 Motor – rated frequency
0.48 Drive operating mode selector
0.49 Security status [M]
0.50 Drive software version [M]
[M] indicates the parameter is for monitoring only
For descriptions of these parameters, see
Appendix D Menu 0 Parameters.
Pr Function User
value
0.11 Pre-ramp reference [M]
0.12 Post-ramp reference [M]
0.13 Motor active-current [M]
0.14 Motor current magnitude [M]
0.15 Current detected indicator [M]
0.16 Drive healthy indicator [M]
0.17 At zero speed indicator [M]
0.18 Brake release indicator [M]
0.19 Current threshold
0.20 Brake release delay
0.21 (Not used)
0.22 (Not used)
0.23 (Not used)
0.24 (Not used)
0.25 (Not used)
0.26 (Not used)
0.27 (Not used)
0.28 (Not used)
0.29 (Not used)
0.30 (Not used)
3-48 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 77
Setting up and using Macro 7
Braking mode
The following may require attention in addition to
the settings made in Chapter 2.
Frequency control
When Macro 7 is selected, the Drive always operates
in brake control; unlike Macros 2 to 5, no digital
input exists to allow switching to and from normal
frequency control.
The frequency of the motor is controlled in the
same way as in normal frequency control.
Reference selection
Use 0.05 Reference selector to select the required
frequency reference source, as follows:
0.05 Source Terminal(s)
0 Analog input 1 or 2 which can be
selected using the LOCAL/REMOTE
contact
1 Analog input 1 5, 6
2 Analog input 2 7
3 Preset frequencies
4 Keypad control
5 ( Do not use)
5 and 6, or 7
The FASt ramp mode is applied. This gives
continuous deceleration under maximum braking
conditions (the ramp mode should not be changed).
A braking resistor is normally required in order to
prevent the
DC-bus voltage from reaching the trip
level.
Stopping mode
The stopping mode is Ramp to a stop.
Analog input mode
The analog inputs are configured for 0 ~ 10V.
See the Commander Gp Advanced User Guide for
selecting other modes.
Brake-control settings
1. The default setting of 10% for parameter 0.19
Current threshold is suitable for the majority of
applications. If required, change the value to
the required percentage of I
This value must ensure that adequate current
will flow through the motor to control the load
when the brake is released.
I
= FLC x 150%
MAX
2. If required, change the setting of 0.20 Brake
release delay to a suitable value (between 0 and
25 seconds) that will ensure a brake release
signal is not issued if the following occur
simultaneously under transient conditions:
• 0.16 Drive healthy indicator changes state
to 1
• 0.17 At zero speed changes state to 0
(see below).
max
Commander GP User Guide
Issue code: gpxu2
Setting Up the Drive 3-49
Page 78
Use this free space for notes
3-50 Setting Up the Drive
Commander GP User Guide
Issue code: gpxu2
Page 79
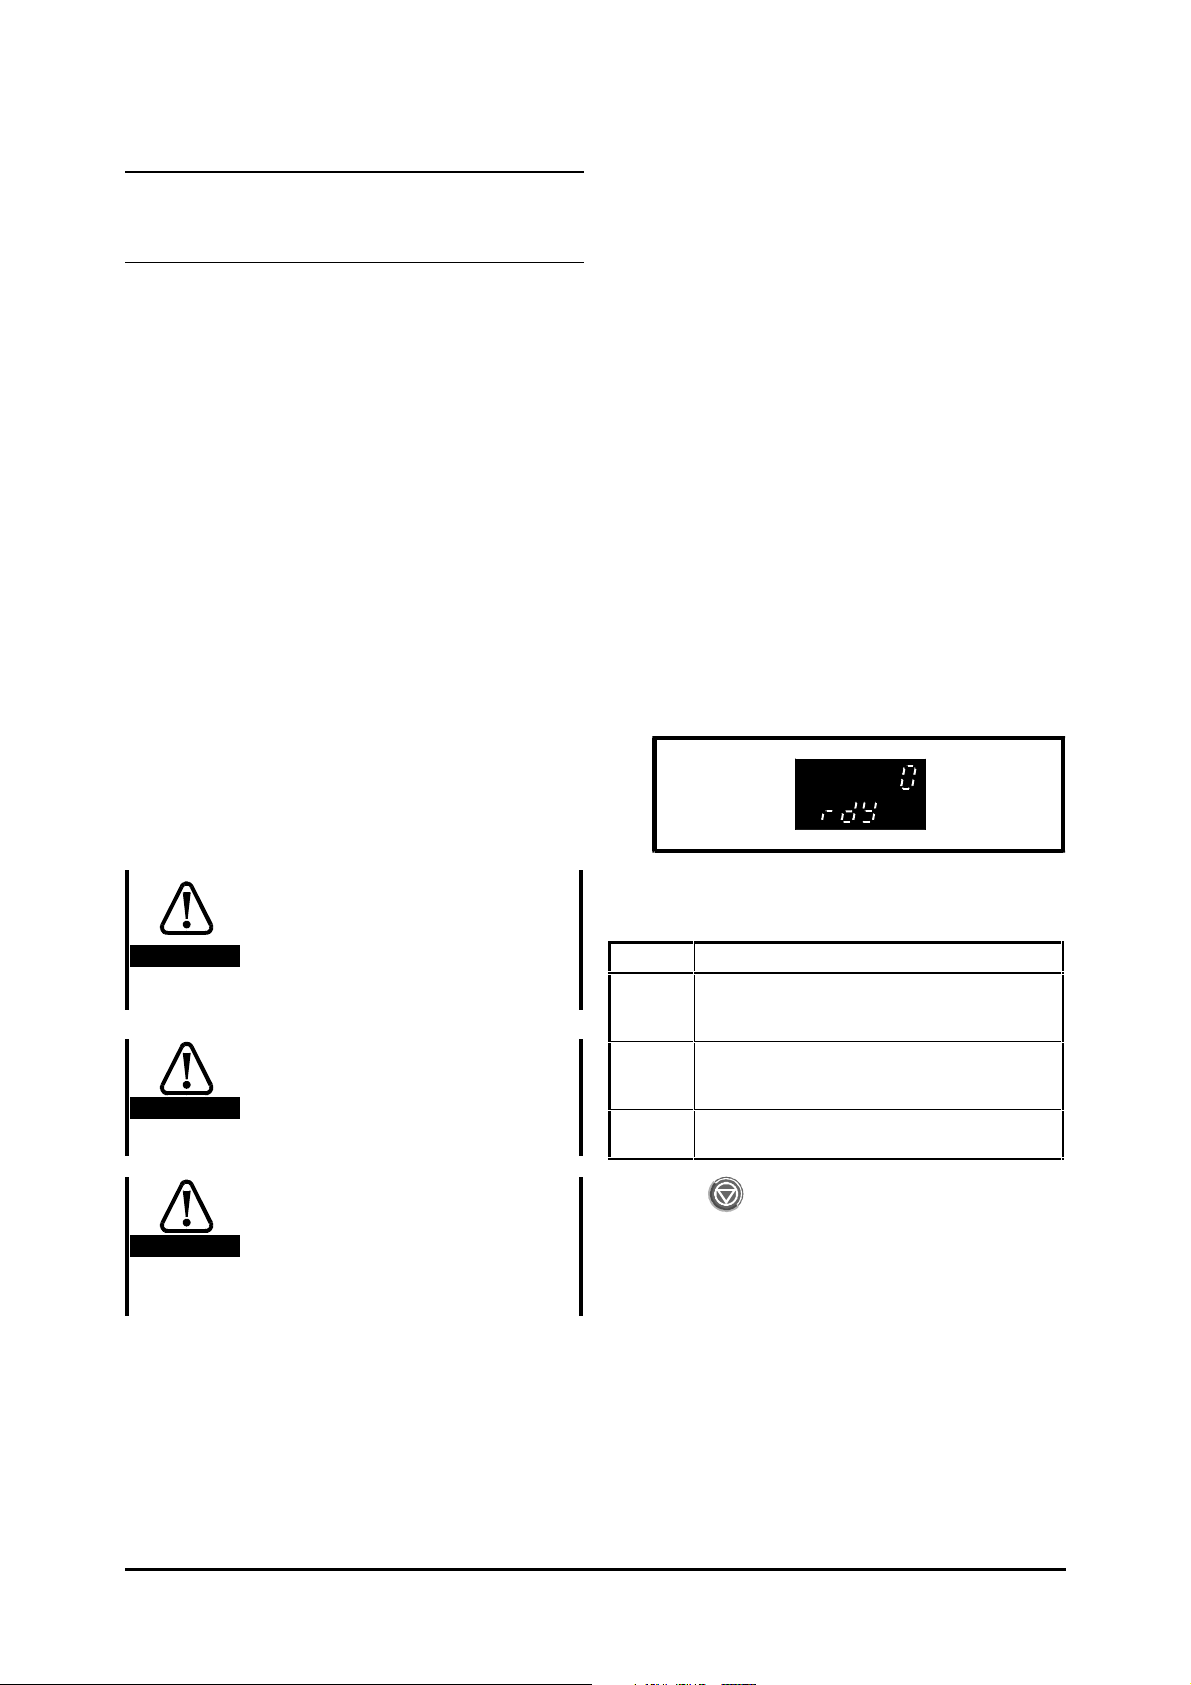
A Programming
Instructions
The instructions in this appendix take you step-bystep through learning how to use the display and
keypad, and alert you to avoid actions that could
cause confusion. It is in your interests to follow
these instructions carefully.
The instructions can be used when the Drive is
operating in Keypad or Terminal mode. They cover
the basic procedure for accessing a numerical
variable parameter. Instructions for accessing other
types of parameter, as well as for more advanced
operations, are given later in this appendix.
A.1 Electrical connections
A.2 Preparation
1. Ensure that terminal 30 is connected to
terminal 31 or that a contact connected to
these terminals is closed.
2. If these instructions are being followed when a
macro other than Macro 1 is enabled, ensure
terminal 8 is connected to terminal 11 or a
motor thermistor is connected to these
terminals. These connections will allow the
Drive to be operated.
3. Ensure that terminals 27 and 28 are
open-circuit, or that contacts connected to
these terminals are open. This will prevent a
motor (if connected) from being driven.
4. Ensure that if a FREQUENCY potentiometer is
connected, it is set at minimum (wiper at
0V common).
Before following the instructions in this chapter
ensure the Drive has been connected in accordance
with the instructions in Chapter 2 Installing the Drive,
in the Installation Guide or Chapter 2 Getting Started
in this User Guide.
When following the instructions in this appendix, It
is your responsibility to connect and disconnect the
AC supply as required.
The terminal cover must be
fitted to the Drive before the
AC supply is connected. If the
Warning
Warning
Warning
cover needs to be removed, the
AC supply must first be
disconnected for ten minutes.
The
AC supply must be
connected to the Drive with
appropriate fuses or
protection, as described in the
Installation Guide.
Adjustment of parameter
values must be performed only
by suitably trained or
experienced personnel.
Incorrect values could be
hazardous.
5. Connect the
6. The display is in Status mode and should indicate
as follows:
If the lower display shows triP and the upper
display shows one of the following, check the
cause and attend to the remedy:
Display Cause and remedy
Motor thermistor not connected, or terminal 8
th
not connected to terminal 11. Make the
necessary connections.
External trip signal received, or terminal 30 not
Et
connected to terminal 31. Make the necessary
connections.
Motor is not connected, one phase is not
rS
connected or the motor is open-circuit.
Press to reset the Drive. The display
should now show rdY
If the lower display still shows triP and another
code is shown on the upper display, see
Appendix E Diagnostics.
AC supply to the Drive.
Commander GP User Guide
Issue code: gpxu2
Programming Instructions A-1
Page 80
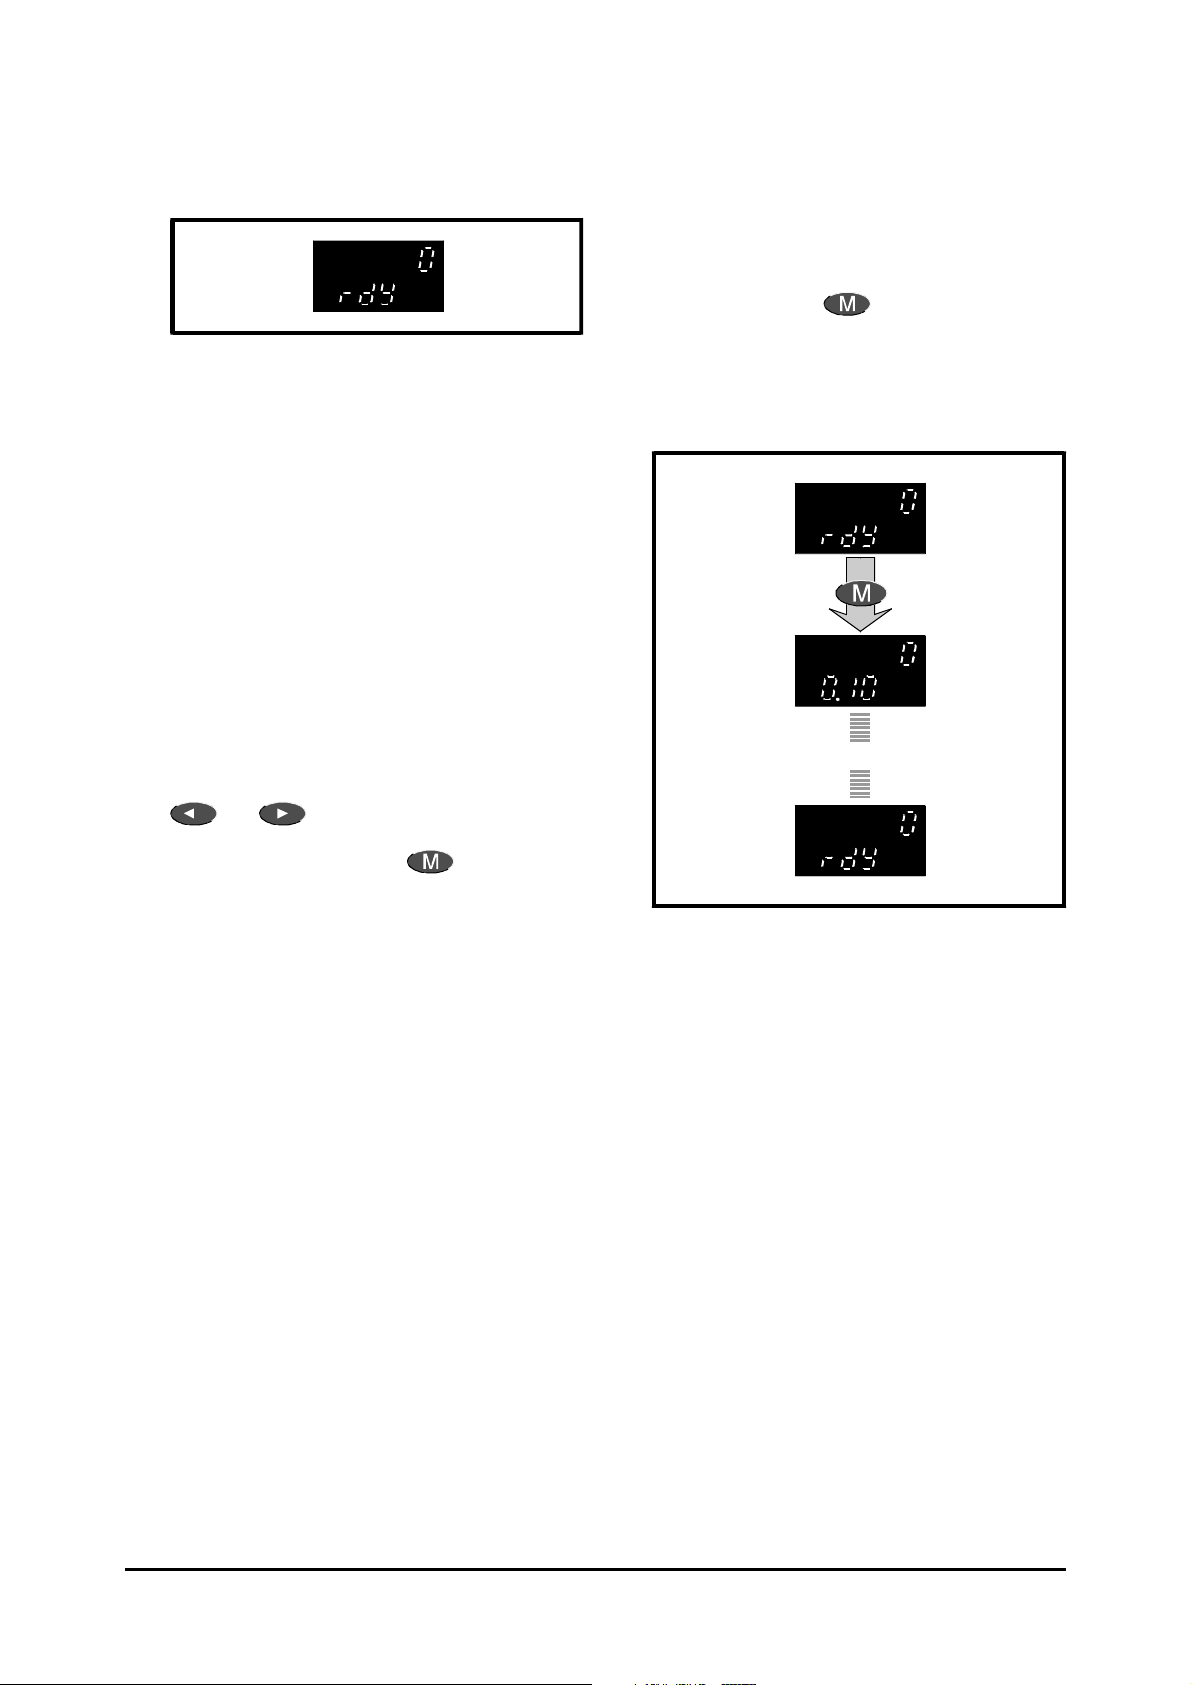
A.3 Status mode
A.5 Entering Parameter mode
and returning to
Status mode
The lower display shows rdY to indicate that the
Drive is ready to drive a motor, as follows:
The upper display indicates the output frequency of
the Drive or the motor speed. This is the value of
parameter 0.10. (The value of a different parameter
could be shown if the Drive has been used
previously.)
A.4 Displaying the parameter
number in Status mode
When the display is in Status mode, the upper
display shows the value of parameter 0.10 (or of the
last parameter to be selected). The number of this
parameter can be shown on the lower display
instead of the Drive status.
1. To show the parameter number, press:
2. To show the status, press: . The status is
or
shown immediately.
1. Momentarily press . The display enters
Parameter mode.
The lower display shows parameter number
0.10. (A different parameter number could be
shown if the Drive has been used previously.)
The display appears as follows:
8 seconds
2. Do not press any keys. After eight seconds, the
display returns to Status mode. This shows
that the display always returns from Parameter
mode to Status mode when no keys are pressed
within eight seconds.
You may repeat these two steps as many times
as required to obtain an understanding of the
operation.
A-2 Programming Instructions
Commander GP User Guide
Issue code: gpxu2
Page 81
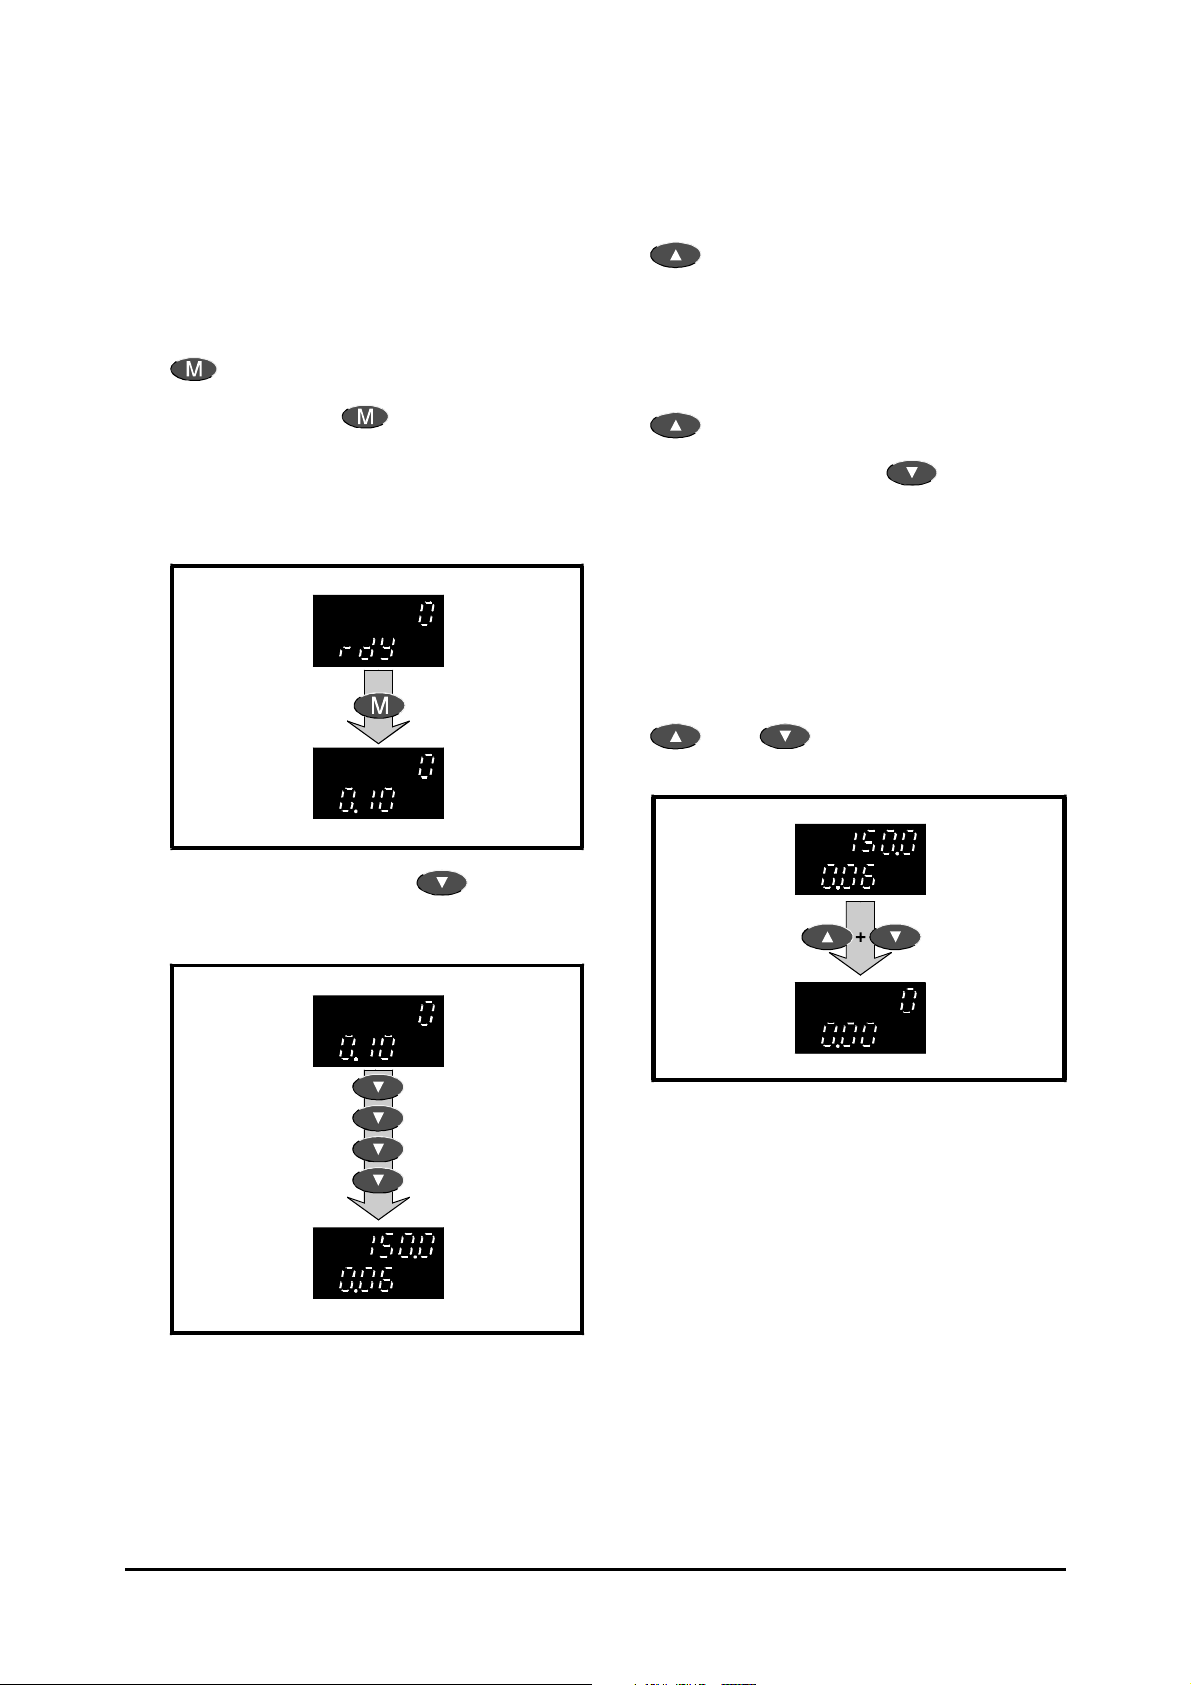
A.6 Selecting
a parameter to access
Scrolling
1. Within eight seconds, press and hold down:
If the display returns to Status mode during the
course of selecting parameters (because no keys
have been pressed for eight seconds), to re-enter
Parameter mode, press:
1. Momentarily press . The display enters
Parameter mode.
Parameter number 0.10, or the number of the
last selected parameter, appears on the lower
display. The value shown on the upper display
remains the same.
The parameter number continuously increases
(scrolls upward) until the highest numbered
parameter in the menu is reached.
2. To start scrolling upward again from parameter
number 0.00, release then re-press:
3. Repeat steps 1 and 2 using
The parameter numbers will now decrease. In
step 2, when parameter 0.00 is reached,
releasing and re-pressing the key will re-start
downward scrolling from the highest numbered
parameter in the menu.
Quick selection of parameter 0.00
1. While the display is in Parameter mode, press at
the same time:
Parameter 0.00 is displayed.
and
2. Within eight seconds, press
The parameter number decreases by one.
Repeat this step until 0.06 is displayed.
Notice that the upper display changes to show
the value of the parameter that is selected.
2. Now select parameter number 0.06.
Commander GP User Guide
Issue code: gpxu2
Programming Instructions A-3
Page 82
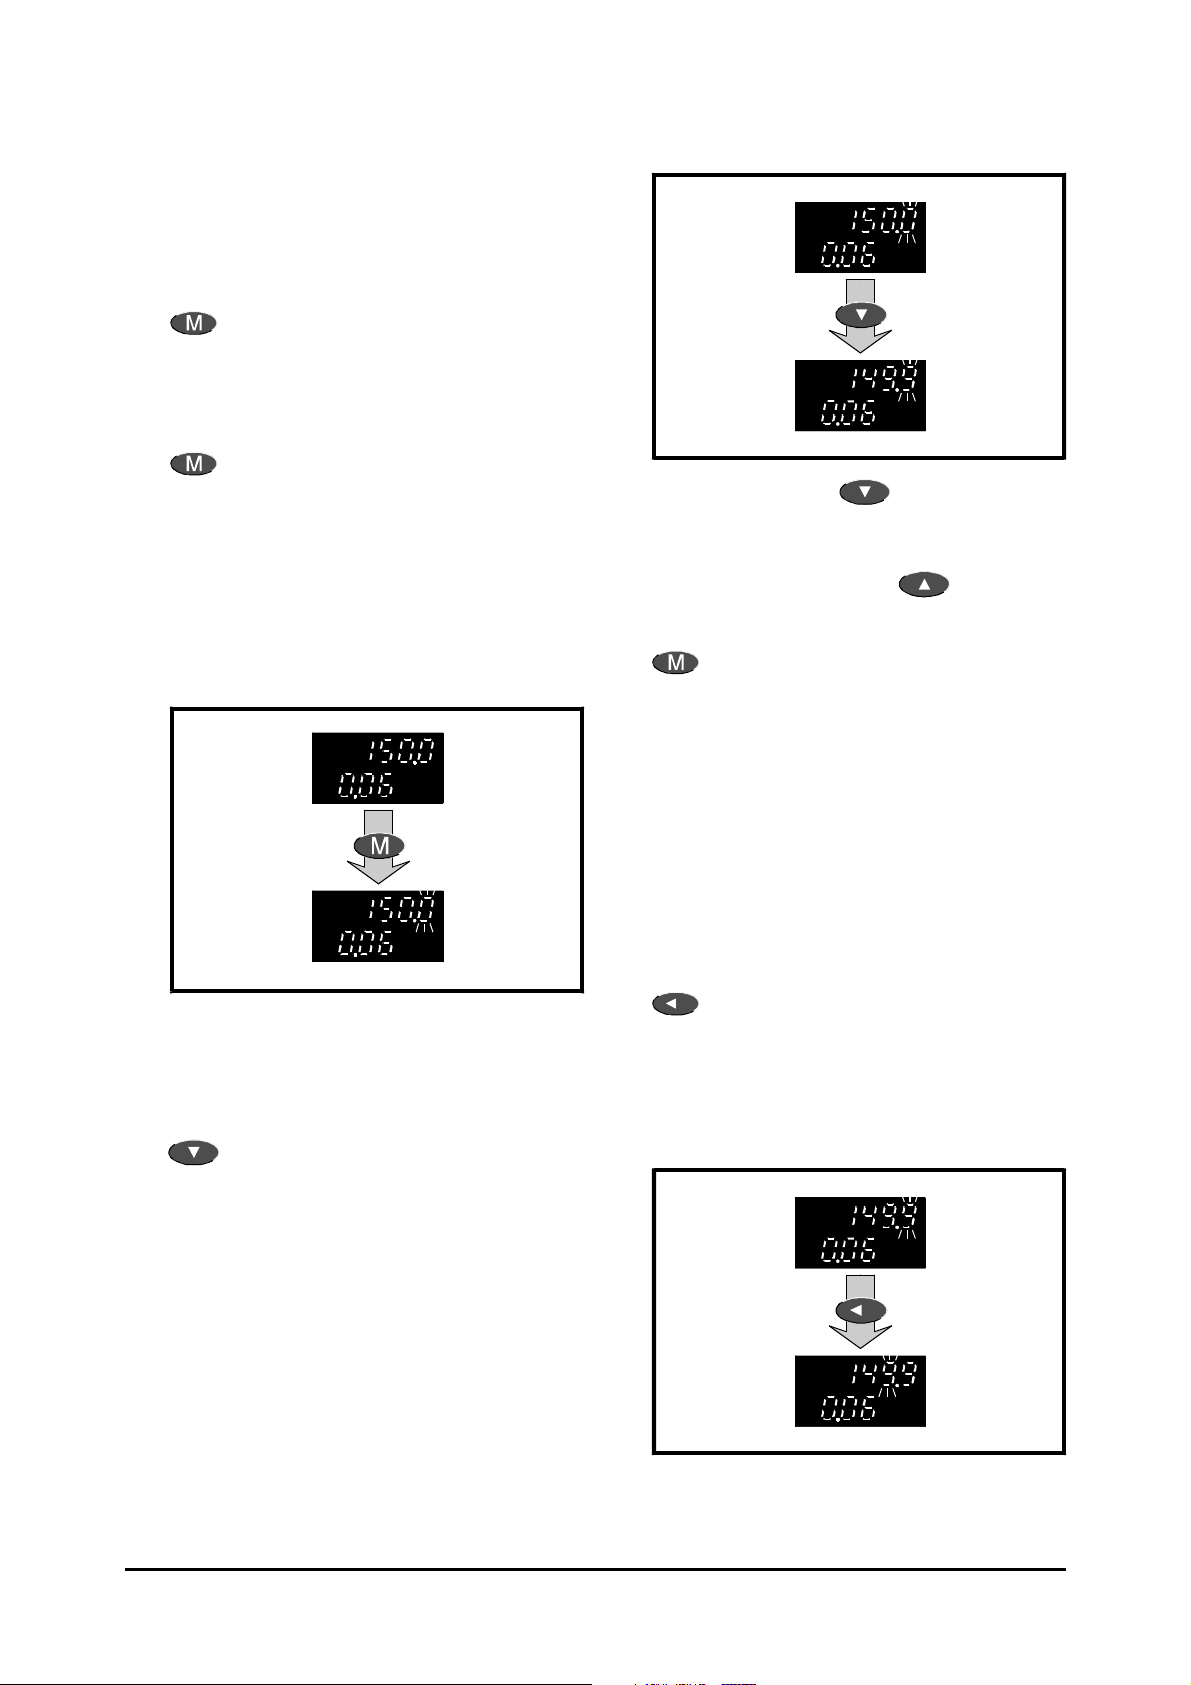
A.7 Changing the value of a
parameter
1. Within eight seconds of selecting parameter
0.06, press:
The display enters Edit mode.
(If more than eight seconds have elapsed, the
display will have returned to Status mode. In
this case, twice press:
On the first press, the display will re-enter
Parameter mode where parameter 0.06 will
again be displayed; on the second press, the
display will enter Edit mode.)
The upper display still shows the value of the
parameter, but the least-significant digit
flashes. (The value shown is the default value
for 0.06; the value displayed may be different if
the Drive has been used previously.)
3. Press and hold down
The value scrolls downward. Release the key
when the required value is reached.
To increase the value, press
4. When the required value is displayed, press:
5. The display returns to Parameter mode. If no
keys are pressed within eight seconds, the
display enters Status mode.
Note that when the display is in Edit mode, it
will not return to Status mode after eight
seconds. You can spend as much time as
required changing the value of a parameter.
2. To decrease the value, momentarily press:
The value of the flashing digit decreases by one.
You can repeat this step as many times as
required. The new value takes effect
immediately.
Making large changes in value quickly
So far, you have changed the value by incrementing
or decrementing the least significant digit. The
speed of change can be increased by selecting, then
scrolling either of the more significant digits, as
follows:
1. When the display is in Edit mode, momentarily
press:
When the key is released, the digit at the left of
the least significant digit flashes. This
operation can be repeated to select the most
significant digit of the display. If this digit is
not currently displayed, it can still be selected.
When selected, a bar appears in its place.
A-4 Programming Instructions
You can then change the value of the newly
selected digit.
Commander GP User Guide
Issue code: gpxu2
Page 83
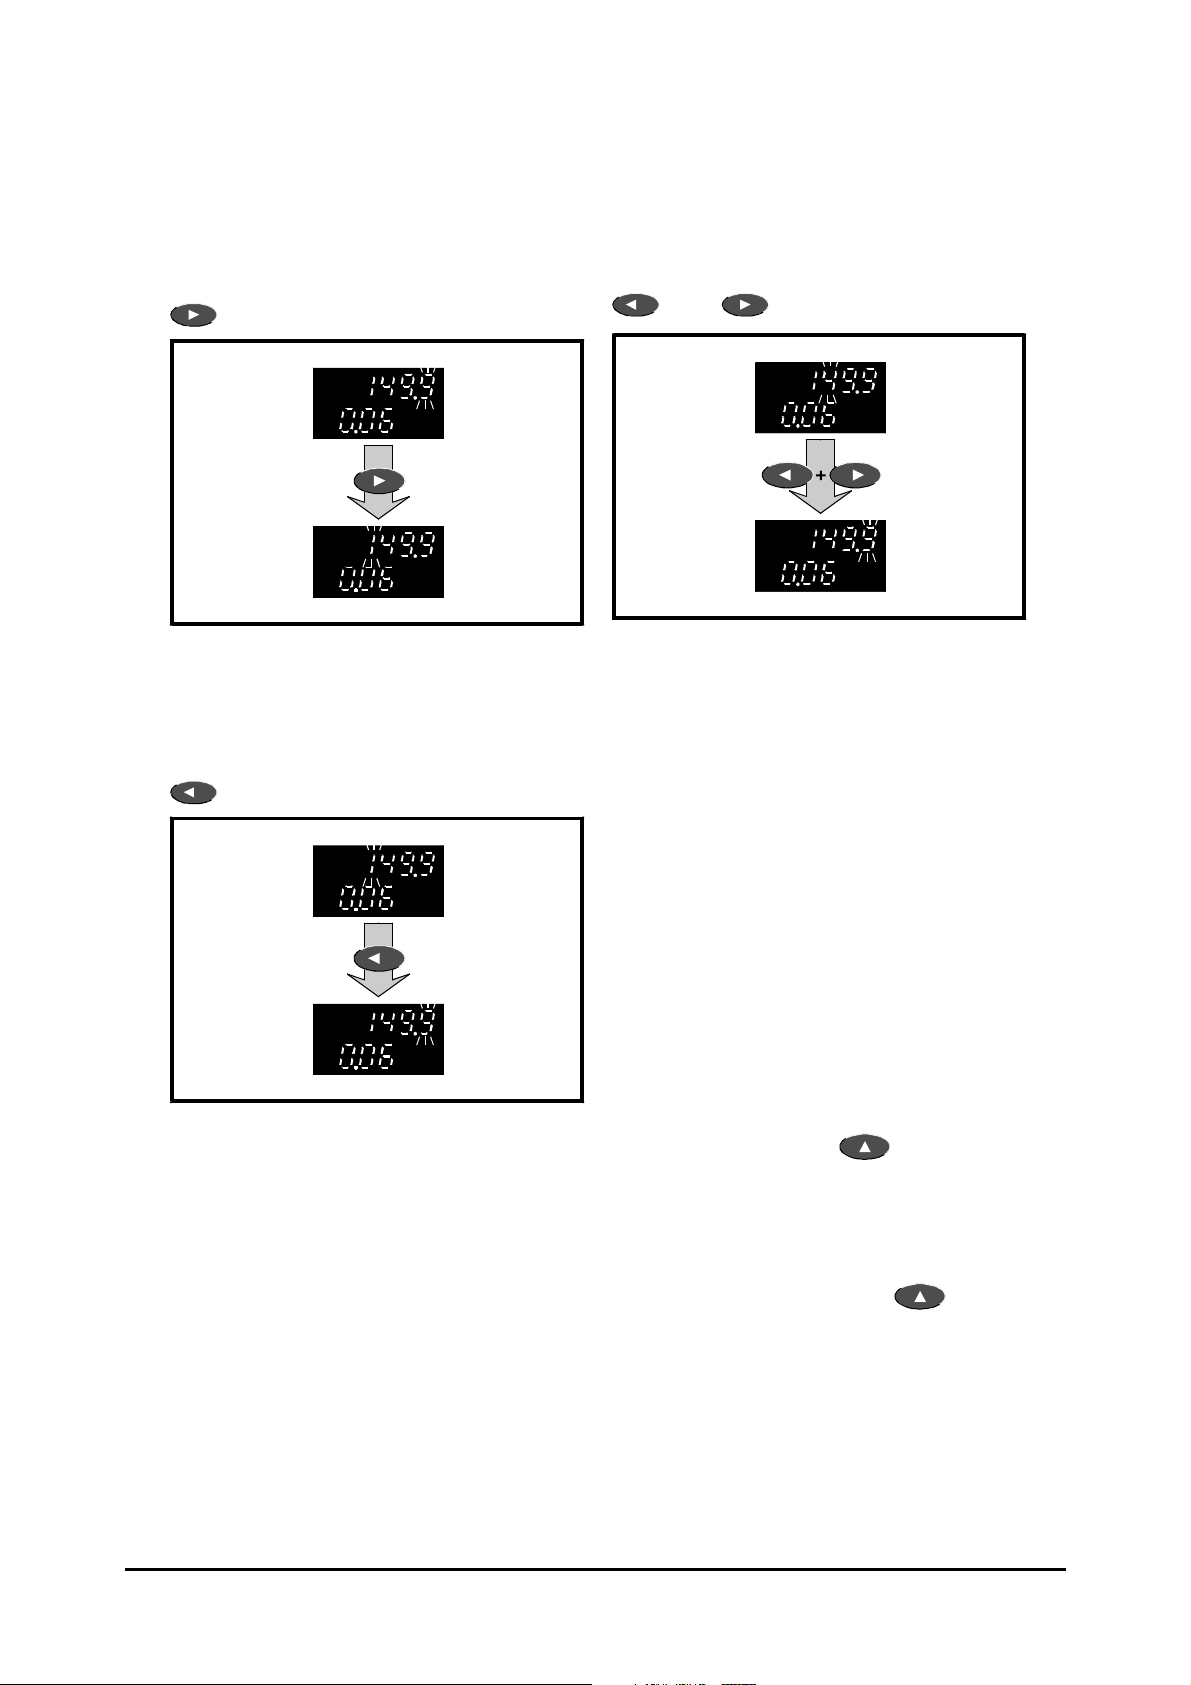
Quick selection from least to most
significant digit
To select the most significant digit when the
least significant digit is flashing, momentarily
press:
Quick selection of the
least significant digit
Irrespective of the digit that is selected, to select
the least significant digit, press at the same time:
and
Quick selection from most to
least significant digit
If the most significant digit of the display (not
just the displayed value) is flashing, to select
the least significant digit, momentarily press:
Reaching the maximum or minimum value
A special condition arises when both the following
occur:
• A digit other than the least significant digit
(LSD) is being increased, and the maximum
value is approached.
• The displayed LSD is not the same value as
the LSD of the maximum value. For
example: if the displayed value is 126.4, and
the maximum value is 217.9, the displayed
LSD of 4 differs from 9.
The special condition allows the value to be set at
either of the following:
• The highest permissible value that contains
the displayed LSD (eg. 4)
• The maximum value for the parameter
Use the following procedure to see how the
operation works:
1. Ensure the selected digit is not the LSD.
2. Press and hold down
maximum value is reached, the entire display
flashes the maximum value (eg. 217.9). Release
the key within three flashes of the display. The
display now shows the highest permissible value
(eg. 216.4) that contains the displayed LSD.
. When the
Commander GP User Guide
Issue code: gpxu2
3. Again press and hold down
maximum value is reached, the entire display
again flashes the maximum value (eg. 217.9).
Release the key after four flashes of the display.
The display now shows the maximum value.
When setting the value at maximum in normal
operation, it is not necessary to follow step 2.
The same principles apply when reaching the
minimum value.
. When the
Programming Instructions A-5
Page 84
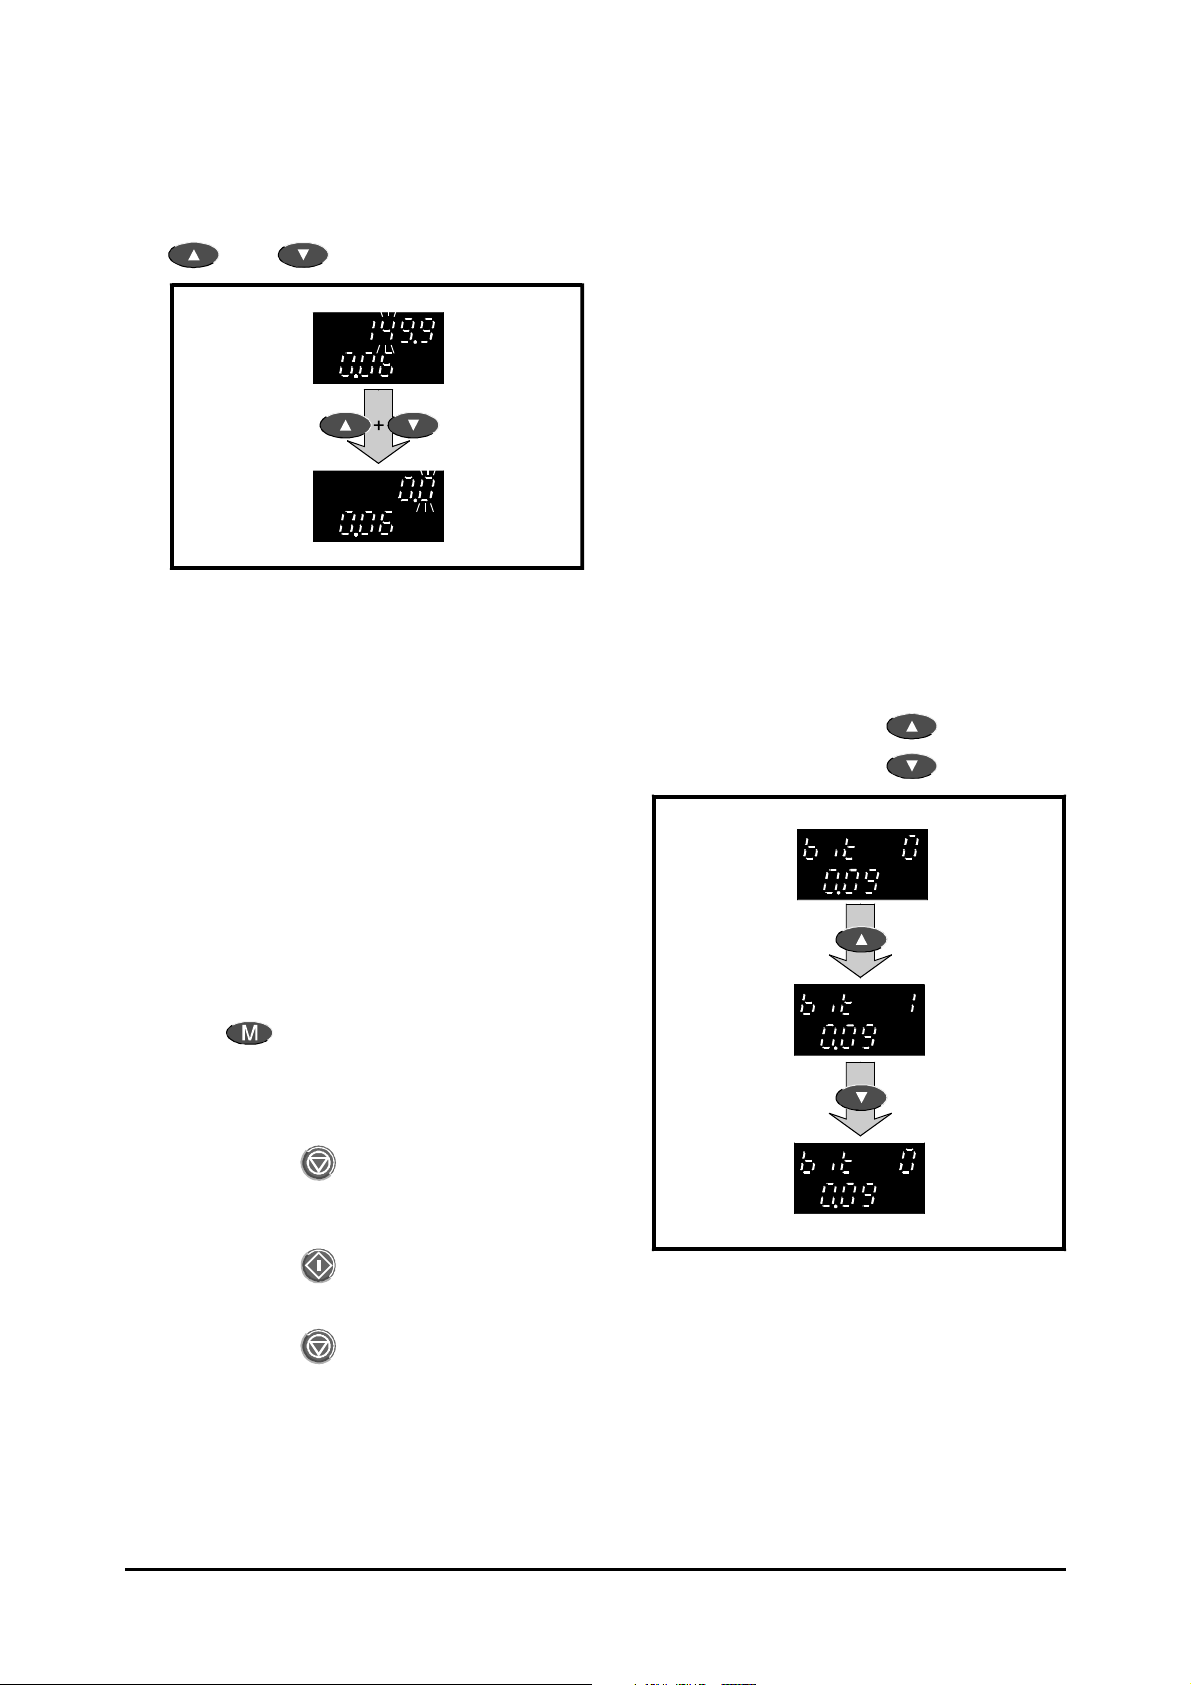
Setting the value at zero
1. Momentarily press at the same time:
A.9 Flashing and non-flashing
digits
and
Bench-testing? Return to default value
If you have followed this procedure while
bench-testing the Drive, return the value to 150
before returning the display to
Parameter mode.
A.8 Saving new
parameter-values
When the display is in Edit mode, the flashing of a
digit indicates that the value of the digit can be
changed. If no digits flash, the parameter cannot be
edited because it is read-only (or protected).
A.10 Negative values
When the value of a bipolar variable parameter is
negative, a minus sign appears at the left of the
displayed value.
A.11 Changing the setting of a
bit parameter
When a bit parameter is selected and Edit mode
entered, the display appears as shown below. bit
appears at the left of the upper display. 0 or 1 is
displayed at the right.
When 0 is displayed, press
When 1 is displayed, press
to select 1.
to select 0.
Use the following procedure to save new
parameter-values. The new values will then apply
each time the
the Drive. If new parameter-values are not saved,
the previously saved (or default) values will apply
each time the
1. Set parameter 0.00 at 1000.
2. Press
mode. Do not press any keys within eight
seconds; the display then enters Status mode.
3. To reset the Drive when it is stopped, press:
To reset the Drive when it is running, press and
hold...
...then press:
Release both keys at the same time.
The new parameter-value(s) are now saved.
AC supply is subsequently applied to
AC supply is applied to the Drive.
. The display returns to Parameter
A-6 Programming Instructions
Commander GP User Guide
Issue code: gpxu2
Page 85
A.12 Selecting a different option
Some variable parameters are used for selecting
among a number of options. These options can be
shown as numbers (as 1 to 5 in parameter 0.05
Reference selector) or as character strings (as Ur_S,
etc, in parameter 0.07 Voltage mode selector).
Use the following procedure:
1. Enter either of the following values in
parameter 0.00:
1233 (Europe, 50Hz
1244 (USA, 60Hz
AC supply frequency)
AC supply frequency)
1. To select a different option, press:
to ascend through the range of options
to descend through the range of options
When the first option is displayed, it is
necessary to ascend through the range in order
to select another option. When the last option
is displayed, it is necessary to descend through
the range.
A.13 Restoring the Drive
to a default configuration
Do not attempt to restore the
Drive to a default
configuration when the Drive is
Warning
When the Drive is despatched from the factory, the
parameters have default values, some of which
depend on the
or USA 60Hz). Consequently, the Drive has a
default configuration for each of these supply
frequencies.
running.
Restoring the Drive to a
default configuration enables
Macro 0 and returns all
parameters to their default
values including the motor
parameters. (If any one of the
macros 1 to 7 has been enabled,
the Drive still reverts to
Macro 0.)
After restoring the Drive to a
default configuration, it will be
necessary for the required
parameter values to be
re-entered before the Drive is
next run.
AC supply frequency (European 50Hz
2. Press
The default values now take effect.
(The Drive is automatically restored to a default
state when the operating mode is changed.)
Saving the default values
If new parameter-values had previously been saved,
these (not the default) values will apply when the
AC supply is next connected to the Drive. If the
default values are required instead, they must be
saved in the same way as new values. Refer to
Saving new parameter-values earlier in this chapter to
save the default values.
A.14 Summary of key operation
Change the display mode
Parameter mode
or
and
and
Edit mode
or
and
or
and
Select a parameter
Select parameter 0.00
Select Menu 0
Change the value of a digit
Change the setting of a bit
parameter
Select a different option
Select the value at 0
Select a different digit
Select the least significant
digit
Commander GP User Guide
Issue code: gpxu2
Programming Instructions A-7
Page 86
A-8 Programming Instructions
Commander GP User Guide
Issue code: gpxu2
Page 87
B Security
Note
Software versions V03.01.07 onward allow
the advanced parameters to be read and
edited via. serial communications
irrespective of the security state.
B.3 Unlocking User Security
When User Security has been set-up and AC power is
applied to the Drive, User Security is automatically
locked. No parameters can be edited except for
parameter .00 in any menu.
Unlock User Security as follows:
1. Select parameter 0.00.
2. Set the value at the User Security code number.
B.1 User-defined Security
The Drive is supplied without User Security having
been set-up. All parameters can be read and all
read–write parameters can be edited.
User-defined Security operates only when it has
been set-up by the user. When locked, it prevents
editing of all parameters except for parameter
0.00.
The code number used to unlock User-defined
Security is defined by the user. This gives
protection against unauthorized editing of
parameters. The code number can be read and
edited only when User Security has been unlocked.
B.2 Setting-up User Security
Set-up User Security as follows:
1. Select parameter 0.34 User security code. The
default value 149 is displayed.
2. Change the value to the required User Security
number which must be within the range 0 to
255. Do not use the default value 149.
3. When the display is returned to Parameter
mode, the displayed value reverts to 149. This
hides the new User Security number.
4. Follow the procedure in Saving new
parameter-values in Appendix A Programming
Instructions.
User Security is now set-up.
All read–write parameters can now be edited.
B.4 Locking User Security
When User security has been set up, and the
AC supply is removed and subsequently re-applied,
User security becomes locked.
To lock User security without removing the
AC supply, set parameter 0.00 at 2000.
B.5 Summary
Condition User Security
Locked
Drive as
despatched
from the
factory
Setting up
security
Saving the code
number
Locking Occurs automatically at power-down or
Unlocking
Changing the
code
Disabling
security
Restoring a
default
configuration
Only parameter 0.00 can be edited; all
other parameters can be read
None
Set 0.34 at 0 ~ 255 (but not 149); the
display reverts to 149 hiding the true
value
Occurs automatically at power-down
when parameter 0.00 is set at 2000
Set parameter 0.00 at the user security
code; the display reverts to 0, hiding the
true value
Set 0.34 at the required value
Set 0.34 at 149 (this value is always
displayed; just enter Edit mode and
return to Parameter mode)
No change
Commander GP User Guide
Issue code: gpxu2
Security B-1
Page 88
B-2 Security
Commander GP User Guide
Issue code: gpxu2
Page 89
C Signal Connections
Descriptions of the control
signal connections
The control circuits are
isolated from the power
circuits in the Drive by basic
Warning
insulation only. The installer
must ensure that the external
control circuits are insulated
from human contact by at least
one layer of insulation rated
for use at the
AC supply
voltage.
If the control circuits are to be
connected to other circuits
classified as Safety Extra Low
Warning
Voltage (SELV) (eg. to a
personal computer), an
additional isolating barrier
must be included in order to
maintain the SELV
classification.
Logic levels of the digital inputs
Logic sense Logic
state
Negative 0 ≥ 15V Open-circuit
Positive 0 ≤ 5V Open-circuit
For positive logic, the supply can be obtained from
terminal 22 +24V output.
Voltage Action
1 ≤ 5V Connected to 0V
1 ≥ 15V Connected to +24V
Signal modes of the analog inputs
The function and possibly the specification of some
terminals change according to the macro
configuration that is enabled. In these cases, the
number of the associated macro configuration(s) is
stated in italics before the function of the terminal.
Where no indication is given, the function and
specification apply to all the macro configurations.
Status relay contact
1
2
Function
Contact voltage rating 240VAC
Contact current rating 5A resistive
Contact minimum current
rating
Contact condition Normally open
Isolation 1.5kV
Update period 8ms
Drive healthy
Installation category 1
10mA
3 0V common (analog)
Common connection for external analog devices.
4 +10V reference voltage
Function Supply for external analog
Voltage tolerance ±1%
Maximum output current 10mA
Protection Current limit
signal devices
Signal Condition Parameter
0 ~ 10V VOLt
0 ~ 20 mA 0–20
20 ~ 0 mA 20–0
4 ~ 20 mA Trip on loss of signal
current
20 ~ 4 mA Trip on loss of signal
current
4 ~ 20 mA Minimum or low speed
on loss of signal current
20 ~ 4 mA Minimum or low speed
on loss of signal current
4 ~ 20 mA Previous speed on loss
of signal current
20 ~ 4 mA Previous speed on loss
of signal current
Commander GP User Guide
Issue code: gpxu2
setting
4–20.Lo
20–4.Lo
4–20.tr
20–4.tr
4–20.Pr
20–4.Pr
Signal Connections C-1
Page 90
Analog input 1
Non-inverting input
5
Inverting input
6
Macro Function
0 1 2 3 5 6 7
4
Type of input Bipolar differential analog
Operating in voltage mode
Voltage range –10V ~ +10V
Absolute maximum
voltage range
Input resistance 100kΩ
Operating in current mode
Current ranges 0 ~ 20mA
Absolute maximum current 50mA
Equivalent input resistance ≤200Ω at 20mA
Resolution 12-bit plus sign
Sampling period ≤2ms
Frequency reference 1 (remote)
Analog torque reference
(For single-ended use,
connect terminal 6 to
terminal 3)
–24V ~ +24V relative to 0V
±24V differential
20mA ~ 0
4 ~ 20mA
20 ~ 4mA
7 Analog input 2
Macro Function
0 1 6 7
5
Type of input Bipolar single-ended analog
Operating in voltage mode
Voltage range –10V ~ +10V
Absolute maximum
voltage range
Input resistance 100kΩ
Operating in current mode
Current ranges 0 ~ 20mA
Absolute maximum current 50mA
Equivalent input resistance ≤200Ω at 20mA
Frequency reference 2 (local)
PID reference
±24V relative to 0V
20mA ~ 0
4 ~ 20mA
20 ~ 4mA
When the Drive is used in torque control (Macro 4),
terminal 7 is used for the analog torque reference.
8 Analog input 3
Macro Function
0 2 3 4 6 7
1 No function
Internal pull-up voltage <5V
Trip threshold resistance 3 kΩ ±15%
Reset resistance 1.9 kΩ ±15%
Short-circuit detection R 51 Ω ±12%
Motor thermistor input*
Macro Function
5
Type of input Bipolar single-ended analog
Operating in voltage mode
Voltage range –10V ~ +10V
Absolute maximum
voltage range
Input resistance 100kΩ
Operating in current mode
Current ranges 0 ~ 20mA
Absolute maximum current 50mA
Equivalent input resistance ≤200Ω at 20mA
PID feedback
±24V relative to 0V
20mA ~ 0
4 ~ 20mA
20 ~ 4mA
* When the Drive is used with Macro 0, 2, 3, 4, 6 or
7 and a motor thermistor is not connected to
terminal 8 (or terminal 15 on the 15-way D type
connector), terminal 8 must be connected to 0V
(terminal 3 or 11).
9 FREQUENCY output signal
10 TORQUE output signal
Type of output Single-ended analog voltage
Bipolar
Maximum output voltage –10V ~ +10V
Maximum output current 10mA peak
Load resistance 1kΩ minimum
Protection Short-circuit proof
Resolution 10-bit plus sign
Update period 8ms
11 0V common (analog)
Common connection for external analog devices.
21 0V common
C-2 Signal Connections
Commander GP User Guide
Issue code: gpxu2
Page 91
22 +24V digital supply
Voltage tolerance ±10%
Nominal output current 200mA (total including
Overload output current 240mA (total including
Protection Current foldback
terminal 24)
terminal 24)
above 240mA
Supply for external digital signal devices.
23 0V common (digital)
Common connection for external digital devices.
Macro Function
24
0 1 4 5 6
AT-SPEED output
2
UP input
3
PRESET SELECT A input
BRAKE RELEASE output
7
25 RESET input
Macro Function
26
0 1
JOG SELECT input
2
DOWN input
3
PRESET SELECT B input
4
AT MIN. SPEED output
6
LIMIT FORWARD input
27 RUN FORWARD input
28 RUN REVERSE input
Macro Function
29
0 1 7
LOCAL/REMOTE input
2
MOT. POT. ENABLE input
3
PRESET ENABLE input
4
TORQUE ENABLE input
5
PID ENABLE input
6
LIMIT REVERSE input
30 EXTERNAL TRIP input
Inputs
Input Negative-logic digital
Voltage range 0V ~ +24V
Absolute maximum
voltage range
Input current when
0V applied
Negative-logic levels Inactive state
Positive-logic levels Inactive state
Type of output Negative-logic digital
Voltage range 0V ~ +24V
Maximum output current 200mA (total including
Overload output current 240mA (total including
–3V ~ +30V
≥3.2mA
(input open-circuit): > +15V
Active state: < +5V
(input open-circuit): < +5V
Active state: > +15V
Outputs
(push-pull)
terminal 22)
terminal 22)
31 0V common (digital)
Common connection for external digital devices.
Commander GP User Guide
Issue code: gpxu2
Signal Connections C-3
Page 92
C-4 Signal Connections
Commander GP User Guide
Issue code: gpxu2
Page 93
D Menu 0 Parameters
D.1 Introduction
Key
Categories of the
fixed-function parameters
The parameters are arranged in the following
categories:
0.00 Configuration and saving
0.01 ~ 0.02 Frequency limits
Type of parameter
RO Read-only
RW Read–write
...selector Select from a number of settings
...select Select from two settings
...enable Make or allow a function to operate
...disable Stop or disallow a function from
operating
...indicator The value can only be read
Limitations of use
R The Drive must be reset for a new value to
take effect.
S The new parameter-value is saved when the
AC supply is disconnected from the Drive.
P Protected parameter; the parameter cannot
be used as the destination parameter for a
programmable input.
Range
Bi Variable parameter having bipolar value
range.
Uni Variable parameter having unipolar value
range.
Txt Variable parameter having text displayed. A
number is stated alongside the setting; this is
displayed on the system controller when the
Drive is accessed by serial communications
Bit Bit parameter
FLC Full-load current (maximum continuous
output current) (see Appendix C Data in the
Installation Guide)
0.03 ~ 0.06 Ramps
Frequency reference selection
Current limit
0.07 ~ 0.09 Voltage boost
0.10 Speed indication
0.31 Macro-number indication
0.32 ~ 0.34 Miscellaneous
0.35 Keypad-reference monitoring
0.36 ~ 0.38 Serial communications
Parameter displayed at power-up
0.39 ~ 0.41 Spinning motor
Autotune
PWM switching frequency
0.42 ~ 0.47 Motor parameters
0.48 Drive software build number
0.49 ~ 0.50 Security and software information
Symbols
ð
Default value
ô
Range of values
[...] Indicates the value of the parameter
~ Indicates a range of values (in the case of bit
parameters, ~ indicates or)
Commander GP User Guide
Issue code: gpxu2
Menu 0 Parameters D-1
Page 94
D.2 Fixed-function parameters
common to all macro
configurations
Configuration
Frequency limits
0.01 Minimum frequency
RW Uni
ô
0 ~ [0.02]
ð
0Hz
0.00 Macro selection,
Configuration,
Saving
RW Uni R
ô
0 ~ 2010
Value Function
1000 Save new parameter-values
1233 Restore parameters to their default values
1244 Restore parameters to their default values
2001 Macro 1
2002 Macro 2
2003 Macro 3
2004 Macro 4
2005 Macro 5
2006 Macro 6
2007 Macro 7
2009 Macro 0
2010 Macro 0
for 50Hz
for 60Hz
Easy mode
Motorized potentiometer
Preset speeds
Torque control
PID control
Axis-limit control
Brake control
General purpose (USA default configuration)
General purpose (EUR default configuration)
AC supply frequency (Europe)
AC supply frequency (USA)
ð
0
Set 0.01 at the required minimum output frequency
of the Drive for both directions of rotation. The
Drive runs at the minimum frequency when the
frequency reference is zero.
[0.01] is a nominal value; slip compensation may
cause the actual frequency to be higher.
(When the Drive is jogging, [0.01] has no effect.)
0.02 Maximum frequency
Maximum frequency
ô
0 ~ 1000.0
RW Uni
ð
50 (
60 (
ð
EURO)
USA)
Hz
Set 0.02 at the required maximum output
frequency for both directions of rotation. The
frequency reference cannot cause the Drive to run
at a frequency higher than [0.02].
[0.02] is a nominal value; slip compensation may
cause the actual frequency to be higher.
(The Drive has additional over-speed protection.)
For operation at motor speeds
greater than twice base speed,
contact the supplier of the
Caution
motor.
Ramps,
Frequency reference selection,
Current limit
Press after setting parameter 0.00 at the
required value.
D-2 Menu 0 Parameters
0.03 Acceleration rate
RW Uni
ô
0 ~ 3200.0
ð
5 s/100Hz
Set 0.03 at the required rate of acceleration. Note
that larger values produce lower acceleration. The
rate applies in both directions of rotation.
0.03 does not apply to jog speed. See Menu 2 in
the Commander Gp Advanced User Guide for jog
acceleration and deceleration rates.
Commander GP User Guide
Issue code: gpxu2
Page 95
0.04 Deceleration rate
I
FLC
RATIO
==
[ . ]0 46
0.06 Current limit
RW Uni
ô
0 ~ 3200.0
ð
10 s/100Hz
Set 0.04 at the required rate of deceleration. Note
that larger values produce lower deceleration. The
rate applies in both directions of rotation.
0.04 does not apply to jog speed. See Menu 2 in
the Commander Gp Advanced User Guide for jog
acceleration and deceleration rates.
0.05 Reference selector
RW Uni
ô
0 ~ 5
ð
(See below)
The default setting of 0.05 depends on the default
configuration of the Drive, as follows:
EUR 0 Terminal mode
USA 4 Keypad mode
Note
Macros 2 to 5: Do not change the setting of
parameter 0.05.
Macro 6: Only settings 0, 1, 2 can be used.
Macro 7: Only settings 0, 1, 2, 4 can be used.
For using setting 3, see the Commander Gp
Advanced User Guide.
Use 0.05 to select the required frequency
reference, as follows:
RW Uni
ô
0 ~ ≥150
ð
150 % I
RATIO
0.06 limits the maximum output current of the
Drive (and hence maximum motor torque) to
protect the Drive and motor from overload.
Set 0.06 at the required maximum torque as a
percentage of the rated torque of the motor, as
follows:
T
[. ] (%)0 06 100==××
R
T
RATED
Where:
T
Required maximum torque
R
T
Motor rated torque
RATED
Alternatively, set 0.06 at the required maximum
active (torque-producing) current as a percentage
of the rated active current of the motor, as follows:
I
[. ] (%)0 06 100==××
R
I
RATED
Where:
I
Required maximum active current
R
I
Motor rated active current
RATED
Refer to Setting the torque-producing current limit in
Chapter 3 Setting up the Drive.
Setting User-
interface
mode
0 Terminal Analog frequency reference
selected by
contact
1 Terminal Analog frequency
reference 1 selected
2 Terminal Analog frequency
reference 2 selected
3 Terminal Preset frequency references
selected (used with
Macro 3)
4 Keypad Frequency controlled by the
keypad
5 (Not used)
Commander GP User Guide
Issue code: gpxu2
Function
LOCAL/REMOTE
Menu 0 Parameters D-3
Page 96
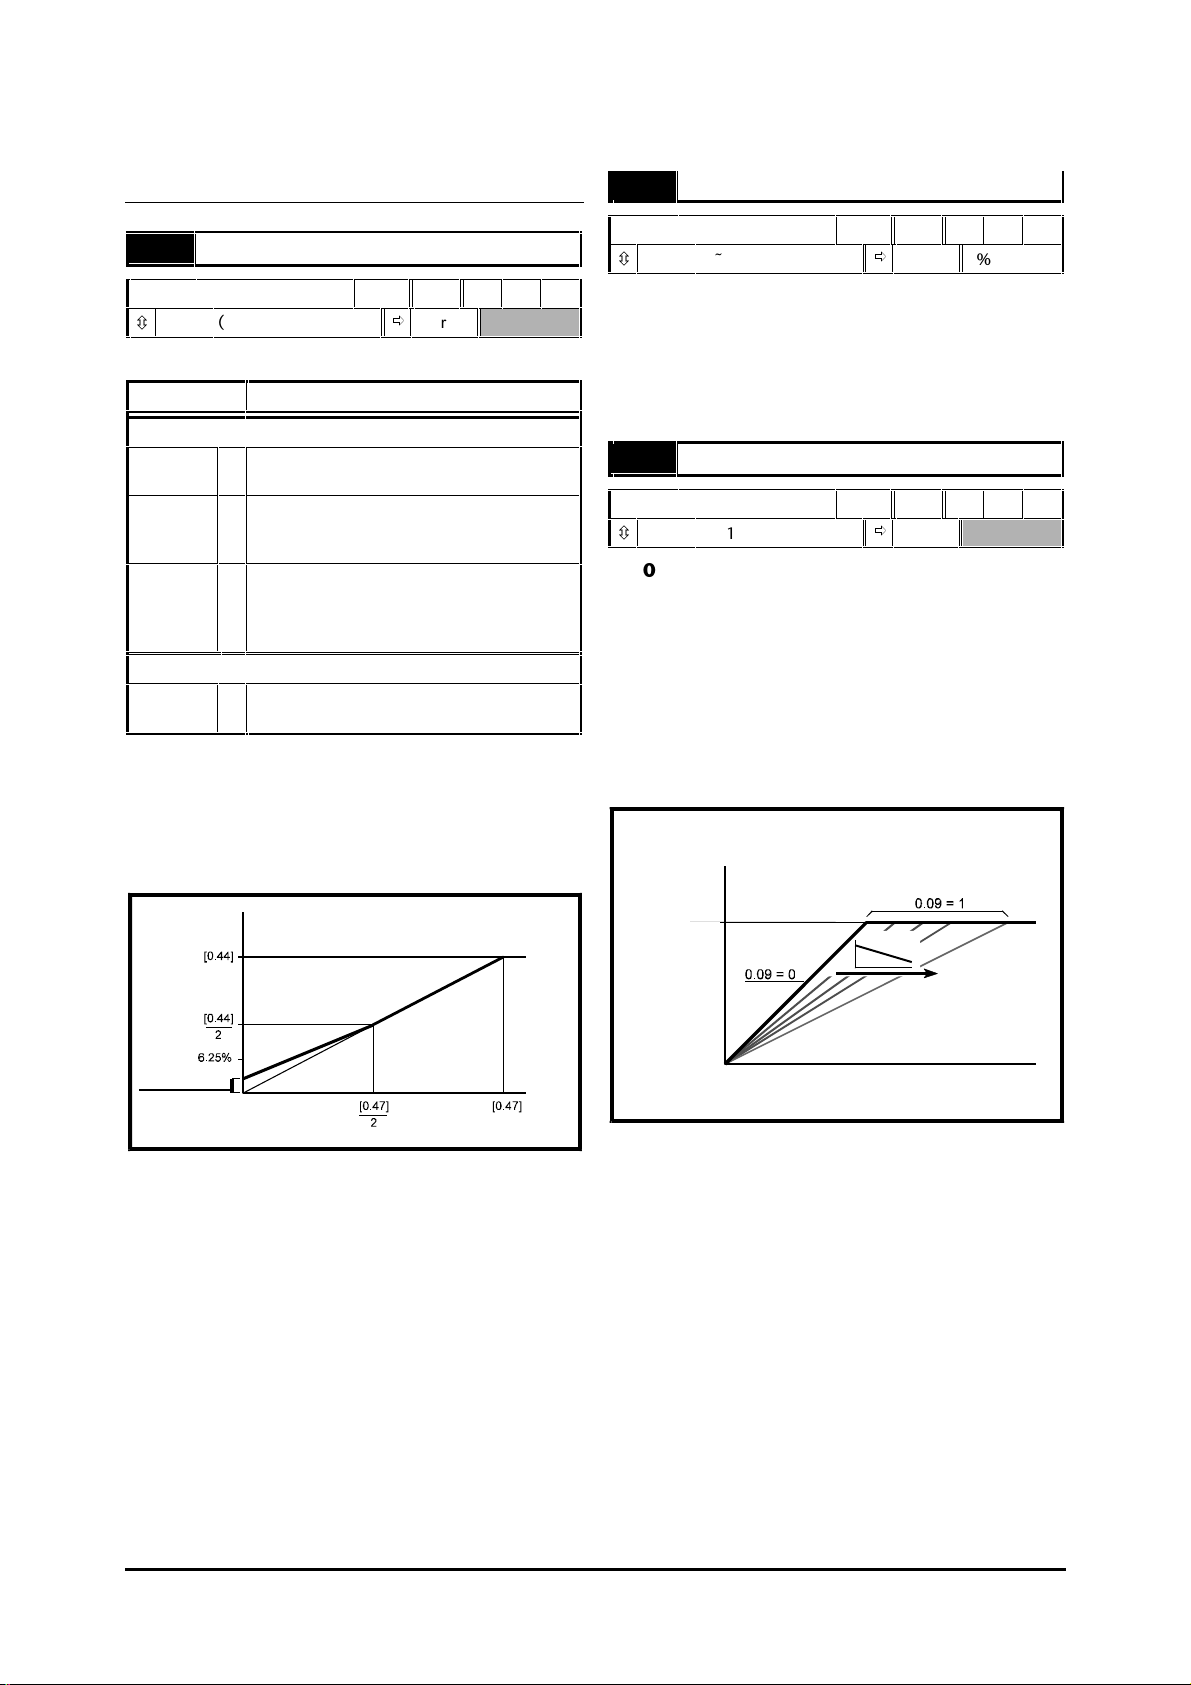
Voltage boost
0.08 Boost voltage
0.07 Voltage mode selector
Voltage mode selector
ô
Setting Function
Ur_S
Ur_I
Ur
Fd
(See below)
Vector modes
0 Motor stator resistance is measured each
time the Drive is started.
1 Motor stator resistance is measured at
power-up if the
closed and no other trip condition exists.
2 Motor stator resistance is not measured
(use this mode only after having used
Ur_S or Ur_I to measure the stator
resistance).
Fixed boost mode
3 Fixed voltage boost that can be manually
adjusted by parameter 0.08 Boost voltage.
RW Uni
ð
Ur_I
EXTERNAL TRIPEXTERNAL TRIP contact is
Use 0.07 to select fixed voltage boost, or Vector
control of voltage boost. Fixed boost requires a
value to be set in 0.08 Boost voltage by the user.
See Figure D–1. Fixed boost should be used when
0.39 Synchronize to a spinning motor is set at 1.
Motor voltage
Boost voltage
ô
0 ~ 25.0
RW Uni
ð
3.0 % x [0.44]
When 0.07 Voltage mode selector is set at Fd, set
0.08 at the required value for the motor to run
reliably at low speeds. See Figure D–1.
Excessive values of 0.08 can cause the motor to be
overheated.
0.09 Dynamic V/f select
Dynamic V/f select
ô
0 ~ 1
RW Bit
ð
0
Set 0.09 at 0 when the V/f characteristic applied to
the motor is to be fixed. It is then based on the
rated voltage and frequency of the motor.
Set 0.09 at 1 when reduced power dissipation is
required in the motor when it is lightly loaded. The
V/f characteristic is then variable resulting in the
motor voltage being proportionally reduced for
lower motor currents. Figure D–2 shows the change
in V/f slope when the motor current is reduced.
Motor
voltage
AC supply
voltage
IMOTOR
[0.08]
Voltage boost
Frequency
Figure D–1 Effect of fixed voltage boost on
the voltage-to-frequency
characteristic
Vector control causes the voltage boost to be
automatically regulated according to the load on
the motor.
Vector control requires the value of stator winding
resistance to be stored in a parameter in the Drive.
The three Vector modes allow the resistance to be
measured under different circumstances.
D-4 Menu 0 Parameters
Frequency
Figure D–2 Fixed and variable
V/f characteristics
Commander GP User Guide
Issue code: gpxu2
Page 97
Speed indication
0.34 User security code
0.10 Estimated motor speed
Estimated motor speed
ô
±6000
RO Bi
ð
RPM
0.10 indicates the value of motor speed that is
estimated from the following:
0.12 Post-ramp frequency reference
0.42 Motor – no. of poles
The value of 0.10 is applied to the analog output on
terminal 9 to indicate estimated speed.
Macro-number indication
0.31 Macro number
RO Uni
ô
0 ~ 7
ð
0.31 indicates the number of the macro
configuration that is currently in operation.
Miscellaneous
0.32 Serial comms. mode
RW Txt R P
ô
ANSI 2
ANSI 4
OUtPUt
INPUt
Use 0.32 to select the required serial
communications mode as follows:
ANSI 2 ANSI protocol, two-wire
ANSI 4 ANSI protocol, four-wire
0.33 Drive rated current (FLC)
ð
ANSI 4
RW Uni S P
ô
0 ~ 255
ð
149
Use 0.34 to set up a User Security code.
Irrespective of the code number entered in 0.34, it
always indicates the default value 149. When 0.34
is actually set at 149, no User Security is applied.
See Setting-up User Security in Appendix B Security.
Keypad-reference monitoring
0.35 Keypad reference
RO Bi S P
ô
± [0.02]
ð
Hz
0.35 indicates the value of the frequency reference
when the Drive is operating in Keypad mode. The
reference is then controlled by the following control
keys (when the display is in Status mode):
The value is automatically saved when the Drive is
powered-down. At the next power-up, the Drive
ramps up to the frequency that applied before the
power-down.
Serial communications,
Parameter displayed after power-up
0.36 Serial comms. baud rate
RW Txt P
ô
4800 (0)
9600 (1)
19200 (2)
2400 (3)
Use 0.36 to select the required baud rate for serial
communications when a Basic serial communications
large option module is fitted in the Drive.
ð
4800
(0)
baud
ô
Commander GP User Guide
Issue code: gpxu2
2.10 ~ 202
RO Uni P
ð
A
0.37 Serial comms. address
RW Uni P
ô
0.0 ~ 9.9
ð
1.1 Group.Unit
Use 0.37 to select the required address for serial
communications when a Basic serial communications
large option module is fitted in the Drive.
Do not enter an address that contains a zero, since
this is used when addressing a group of Drives.
Menu 0 Parameters D-5
Page 98
0.38 Initial parameter displayed
RW Uni P
ô
0.00 ~ 0.50
ð
0.10
At the time the AC supply is connected to the Drive,
parameter 0.10 Estimated motor speed is
automatically pre-selected as the initial parameter
to be displayed. This results in the following:
1. After the
AC supply is connected to the Drive,
and before any other parameter is selected, the
value of parameter 0.10 is shown on the upper
display. This allows the motor speed to be
monitored without the need to select the
parameter.
2. If the keypad is subsequently used to select
another parameter, the value of the newly
selected parameter is displayed in place of the
initial parameter.
To select a different parameter to be displayed initially,
enter the required parameter number in 0.38 (eg. to
display 0.12 Post-ramp reference, enter 0.12).
Spinning motor,
Autotune,
PWM switching frequency
0.39 Synchronize to a spinning motor
RW Bit
ô
0 ~ 1
Set 0.39 at 1 for the Drive always to automatically
synchronize itself to the motor if the motor is
already rotating when the Drive is started.
If the Drive is started when the motor is already
spinning and 0.39 is set at 0, the Drive cannot
detect the speed of the motor; the normal
operation of the Drive will cause the motor to be
braked to a stand-still in the same way as
DC injection braking. The Drive will then accelerate
the motor to the value of the frequency reference.
Notes
The Drive can be synchronized to a single
motor only. If more than one motor is
connected to the Drive, this function should
not be used.
For the Drive to operate correctly during
and after synchronization, parameter
0.07 Voltage mode selector must be set at Fd.
The Drive starts a sequence of operations at one
quarter of the rated motor voltage in order to
detect the frequency associated with the speed of
ð
0
the motor. The sequence is stopped when the
motor frequency is detected. The stages in the
sequence are as follows:
1. The frequency of the Drive is set at maximum
(the value of 0.02) in the direction that the
motor was last driven. (If the
AC supply to the
Drive was interrupted before an attempt is
made to synchronize to a spinning motor, the
Drive always starts in the forward direction.)
2. The frequency is reduced to zero. If the motor
frequency is detected during the reduction in
Drive frequency, the test is stopped. The Drive
frequency is set at the detected motor
frequency and the Drive takes control of the
motor.
3. If the motor frequency is not detected, the
Drive is set at maximum frequency in the
opposite direction, and the test is repeated.
4. If the motor frequency is still not detected, the
Drive frequency is set at 0Hz, and the Drive
takes control of the motor.
0.40 Autotune
RW Bit P
ô
0 ~ 1
ð
0
Set 0.40 at 1 to start the Autotune sequence. See
Autotune in Chapter 2 Getting Started.
0.41 PWM switching frequency
RW Txt P
ô
3, 4.5, 6, 9, 12
ð
3 kHz
See PWM switching frequency in Planning the installation in
Chapter 2 Installing the Drive in the Installation Guide.
Thermal protection
Intelligent thermal modelling in the Drive effectively
monitors the junction temperature of the IGBTs in
the power stage. When the junction temperature is
calculated to reach the maximum permissible value,
two levels of protection occur, as follows:
1. When a
or 12kHz is selected, the
frequency is automatically halved. This reduces
switching losses in the IGBTs. (The value of
parameter 0.41
at the value set by the user.)
Then at one-second intervals, the Drive will
attempt to return the
to the original value. This will be successful
when the thermal modelling has calculated that
the temperature has reduced sufficiently.
PWM switching frequency of 6kHz, 9kHz
PWM switching
PWM switching frequency remains
PWM switching frequency
D-6 Menu 0 Parameters
Commander GP User Guide
Issue code: gpxu2
Page 99
2. If the junction temperature continues to rise
(due to the output current) after the
PWM
switching frequency has been halved, and the
temperature reaches the maximum permissible
value, the Drive will trip. The display will
indicate trip code Oh1.
Motor parameters
0.42 Motor – number of poles
RW Txt P
ô
2 ~ 32
Enter the number of motor poles (not pole pairs).
(See Configuring the Drive for the motor in Chapter 2
Getting Started.)
ð
4 poles
0.46 Motor – rated current
RW Uni
ô
0 ~ FLC
ð
FLC A
FLC is the maximum permissible continuous output
current of the Drive up to 40°C ambient
temperature and 3kHz
PWM switching frequency.
Enter the value from the rating plate of the motor.
(See Configuring the Drive for the motor in Chapter 2
Getting Started.)
0.47 Motor – rated frequency
RW Uni
ô
0 ~ 1000.0
ð
50 (
60 (
EUR)
USA)
Hz
0.43 Motor – power factor
RW Uni S P
ô
0 ~ 1.000
ð
0.92
When Autotune is used, the power factor of the
motor is measured by the Drive and stored in 0.43.
The value can be seen when 0.43 is accessed. The
value may be higher than the value stated on the
motor rating plate.
If Autotune is not used, enter the value in 0.43.
0.44 Motor – rated voltage
RW Uni
Commander GP
ô
EUR
0 ~ 400
ô
USA
0 ~ 480
Commander GP LV
ô
EUR
0 ~ 240
ô
USA
0 ~ 240
ð
400 (EUR)
ð
460 (USA)
ð
ð
220
220
V
V
V
V
Enter the value from the rating plate of the motor.
(See Configuring the Drive for the motor in Chapter 2
Getting Started.)
Enter the value from the rating plate of the motor.
(See Configuring the Drive for the motor in Chapter 2
Getting Started.)
Drive software build number
0.48 Drive software build number
RO Uni
ô
0 ~ 99
ð
Status information
0.49 Security status
RO Uni
ô
0 ~ 1
0.49 normally indicates 1. This shows that access
to the advanced parameters is not possible.
0.50 Software version number
ô
1 .00~ 99.99
ð
1
RO Uni P
ð
0.45 Motor – rated speed
RW Uni
ô
0 ~ 6000
ð
0
RPM
Enter the value from the rating plate of the motor.
(See Configuring the Drive for the motor in Chapter 3
Setting up the Drive.)
Commander GP User Guide
Issue code: gpxu2
Menu 0 Parameters D-7
Page 100
D.3 Parameters specific
4
û
4
û
0.14
0
1
1
0
to the macro configurations
Since parameters 0.11 to 0.30 are specific to
individual macros, most parameter numbers appear
more than once in this section, but with different
names; these are variants on the parameter number.
For guidance, a table headed Applicable to Macros...
appears for each parameter variant. (In places, the
listing is not able to be in strict numerical order.)
A table at the end of this appendix shows the
variants for all the macros (except Macro 1 which
does not use these parameters).
0.11 Pre-ramp reference
0.12 Post-ramp reference
0.14 Jog reference
RW Uni
ô
Applicable to Macros...
0123
0 ~ 400.0
üûûû
ð
1.5 Hz
567
ûûû
Enter the required value of jog frequency. The
frequency limits affect the Drive when jogging as
follows:
Frequency-limit parameter Limit applies
0.01 Minimum frequency
0.02 Maximum frequency
No
Yes
RO Bi
ô
Applicable to Macros...
01234567
±1000.0
ð
HZ
üûüüüüüü
When the frequency is constant, [0.12] = [0.11].
During acceleration and deceleration, the two
values may differ.
[0.12] differs from [0.11] also under either of the
following conditions:
• When the Drive is in current limit
• During braking in a standard ramp (Stnd.Hd
or Std.Ct) mode.
0.13 Motor active-current
RO Bi
ô
Applicable to Macros...
01234567
±FLC
ð
A
üûüüüüüü
Note
So that jog can be selected, the Drive must
be operated in either Macro 0 or Macro 1
and in Terminal mode.
0.14 Limit forward indicator
RO Bit P
ô
Applicable to Macros...
0123
0 ~ 1
ûûûû
0.14 indicates the state of the LIMIT FORWARD
contact, as follows:
0.21 LIMIT FORWARD
0 Open
0 Closed
1 Closed
1 Open
contact
ð
567
ûüû
Condition
Limit not reached
Limit reached
Limit not reached
Limit reached
When the motor is being driven below its rated
speed, the torque is proportional to [0.13].
D-8 Menu 0 Parameters
Commander GP User Guide
Issue code: gpxu2
 Loading...