

Page 1
TEROS 21 GEN 2 INTEGRATOR GUIDE
SENSOR DESCRIPTION
The TEROS 21 Soil Water Potential Sensor measures a wide range of soil water potentials without user
maintenance. This dielectric water potential sensor can be packed into a hole, plugged into a data logger, and
left to log water potential data. While the TEROS 21 sensor does not have the accuracy of tensiometers, its
extended range makes this sensor ideal for measuring the water potential in natural systems or other drier
systems where cavitation of tensiometers is a concern. The added temperature measurements can be used to
determine approximate soil water potential in frozen soils.
NOTE: The TEROS 21 measures the matric component of water potential. For more information on matric potential and the other
components of water potential visit Defining water potential.
APPLICATIONS
• Deficit irrigation monitoring and control
• Water potential monitoring in the vadose zone
• Crop stress
• Waste water drainage studies
• Plant water availability
• SDI-12 implementation
18407-00
6.30.2020
ADVANTAGES
• Three-wire sensor interface: power, ground, and data
• Digital sensor communicates multiple measurements
over a serial interface
• Robust thermistor for accurate temperature measurements
• Low-input voltage requirements
• Low-power design supports battery-operated data loggers
• Robust epoxy encapsulation resists corrosive environments
• Supports SDI-12 or DDI serial communications protocols
• Modern design optimized for low-cost sensing
• Does not require a skilled operator
• Can measure drier systems where tensiometer cavitation is
a concern
• Needs no user maintenance
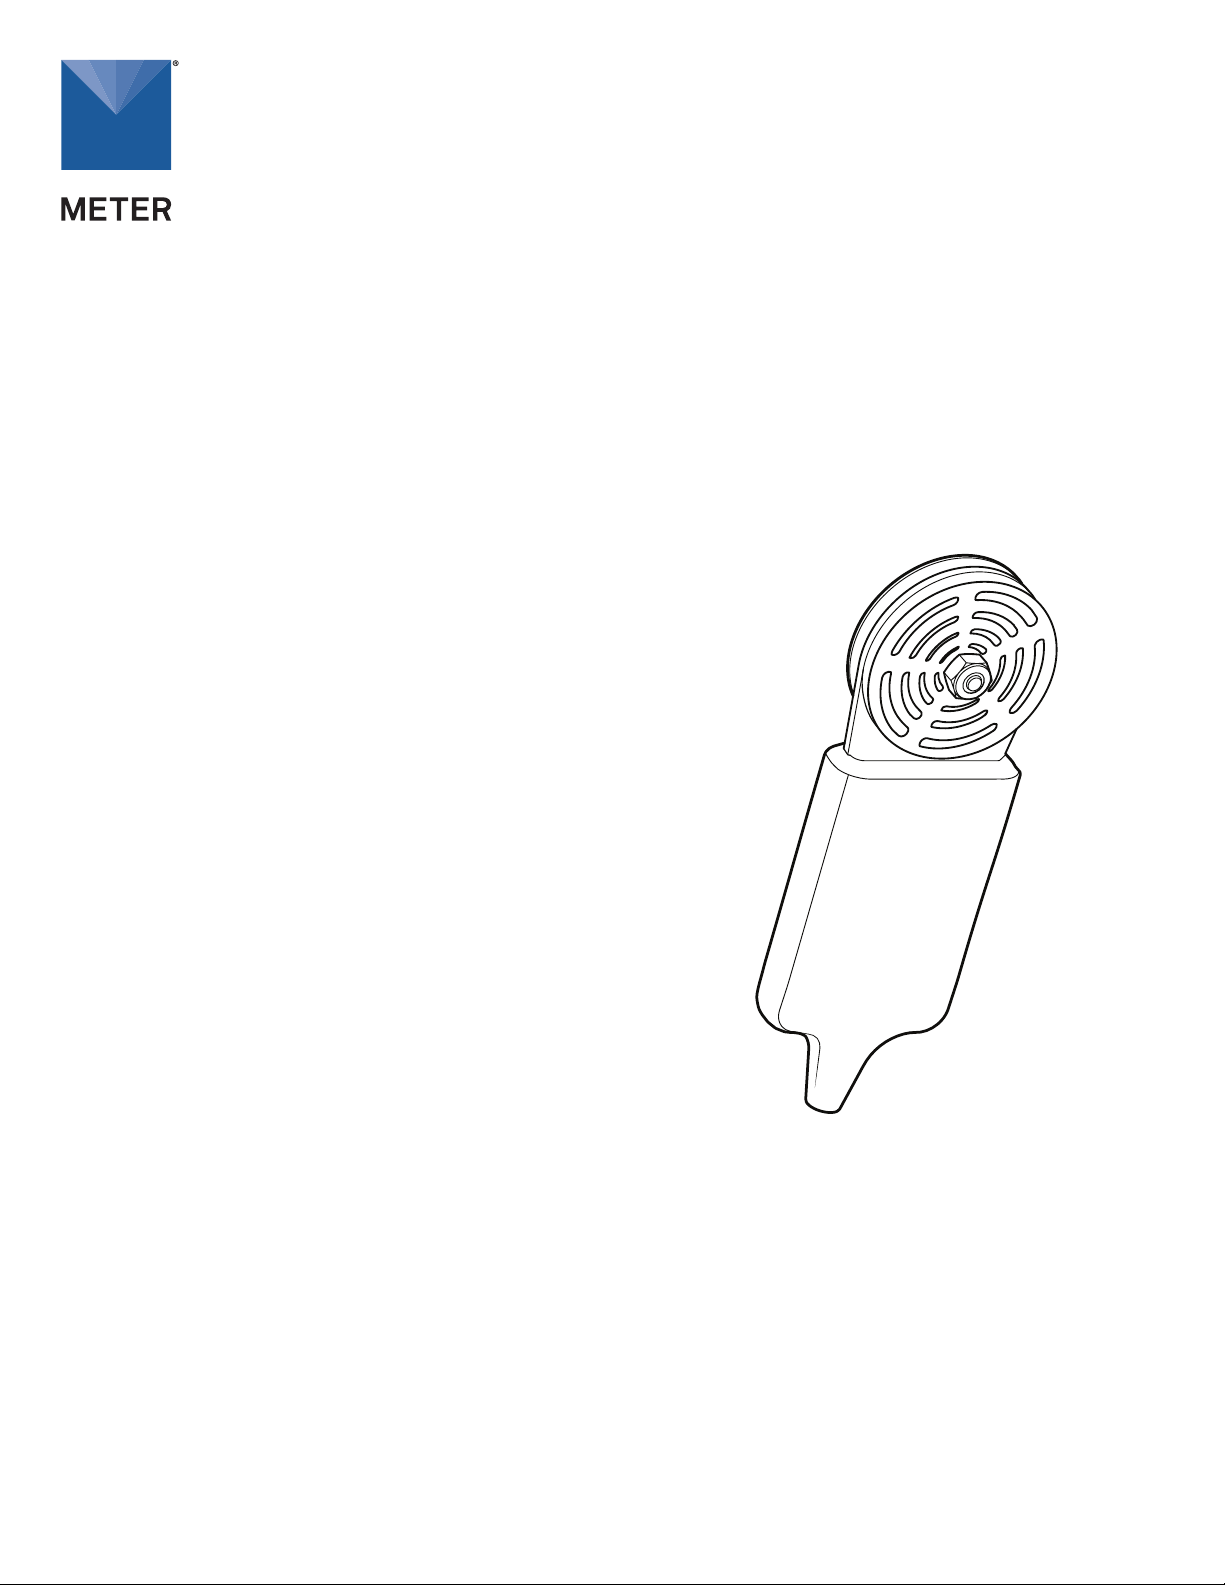
Figure 1 TEROS 21 sensor
PURPOSE OF THIS GUIDE
METER provides the information in this integrator guide to help TEROS 21 Soil Water Potential Sensor
customers establish communication between these sensors and their data acquisition equipment or field
data loggers. Customers using data loggers that support SDI-12 sensor communications should consult the
data logger user manual. METER sensors are fully integrated into the METER system of plug-and-play sensors,
cellular-enabled data loggers, and data analysis software.
COMPATIBLE FIRMWARE VERSIONS
This guide is compatible with firmware versions 5.00 or newer for the TEROS 21 Gen 2.
METER Group, Inc. USA
2365 NE Hopkins Court, Pullman, WA 99163
Page 2
SPECIFICATIONS
MEASUREMENT SPECIFICATIONS
TEROS 21 GEN 2
Water Potential
Range
Resolution
Accuracy
−5 to −100,000 kPa (1.70 to 6.00 pF)
0.1 kPa
±(10% of reading + 2 kPa)
from −9 to −100 kPa
NOTE: TEROS 21 can read up to 0 kPa when on a wetting path.
The air entry of the soil limits the performance of the sensor
to −5 kPa on the drying curve.
NOTE: TEROS 21 is not well calibrated beyond
more information on using the TEROS 21 beyond this range,
see the TEROS 21 User Manual.
−100 kPa. For
COMMUNICATION SPECIFICATIONS
Output
RS-232 (TTL) with 3.6-V or SDI-12
communication protocol
PHYSICAL SPECIFICATIONS
Dimensions
Length 9.6 cm (3.8 in)
Width 3.5 cm (1.4 in)
Height 1.5 cm (0.6 in)
Sensor Diameter
3.2 cm (1.3 in)
Operating Temperature Range
Minimum –40 °C
Typical NA
Maximum +60 °C
NOTE: Sensors may be used at higher temperatures under
certain conditions; contact Customer Support for assistance.
Dielectric Measurement Frequency
70 MHz
Temperature
Range −40 to +60 °C
Resolution 0.1 °C
Accuracy ±1 °C
Data Logger Compatibility
METER ZL6, EM60, and Em50 data loggers or
any data acquisition system capable of 3.6- to
15-VDC power and serial or SDI-12 communication
Cable Length
5 m (standard)
75 m (maximum custom cable length)
NOTE: Contact Customer Support if a nonstandard cable
length is needed.
Connector Types
3.5-mm stereo plug connector or stripped and
tinnedwires
ELECTRICAL AND TIMING CHARACTERISTICS
Supply Voltage (VCC to GND)
Minimum 3.6 VDC
Typical NA
Maximum 15.0 VDC
Digital Input Voltage (logic high)
Minimum 2.8 V
Typical 3.6 V
Maximum 5.0 V
Digital Input Voltage (logic low)
Minimum –0.3 V
Typical 0.0 V
Maximum 0.8 V
Digital Output Voltage (logic high)
Power Line Slew Rate
Current Drain (during measurement)
2
Minimum NA
Typical 3.6 V
Maximum NA
Minimum 1.0 V/ms
Typical NA
Maximum NA
Minimum 3.0 mA
Typical 5.0 mA
Maximum 16.0 mA
Page 3
TEROS 21 GEN 2
Power (brown)
Ground
n
Current Drain (while asleep)
Minimum NA
Typical 0.03 mA
Maximum NA
Power-Up Time (DDI serial)
Minimum NA
Typical 50 ms
Maximum NA
Power-Up Time (SDI-12)
Minimum NA
Typical 225 ms
Maximum NA
Power-Up Time (SDI-12, DDI disabled)
Minimum NA
Typical 175 ms
Maximum NA
Measurement Duration
Minimum 175 ms
Typical NA
Maximum 200 ms
COMPLIANCE
Manufactured under ISO 9001:2015
EM ISO/IEC 17050:2010 (CE Mark)
EQUIVALENT CIRCUIT AND CONNECTION TYPES
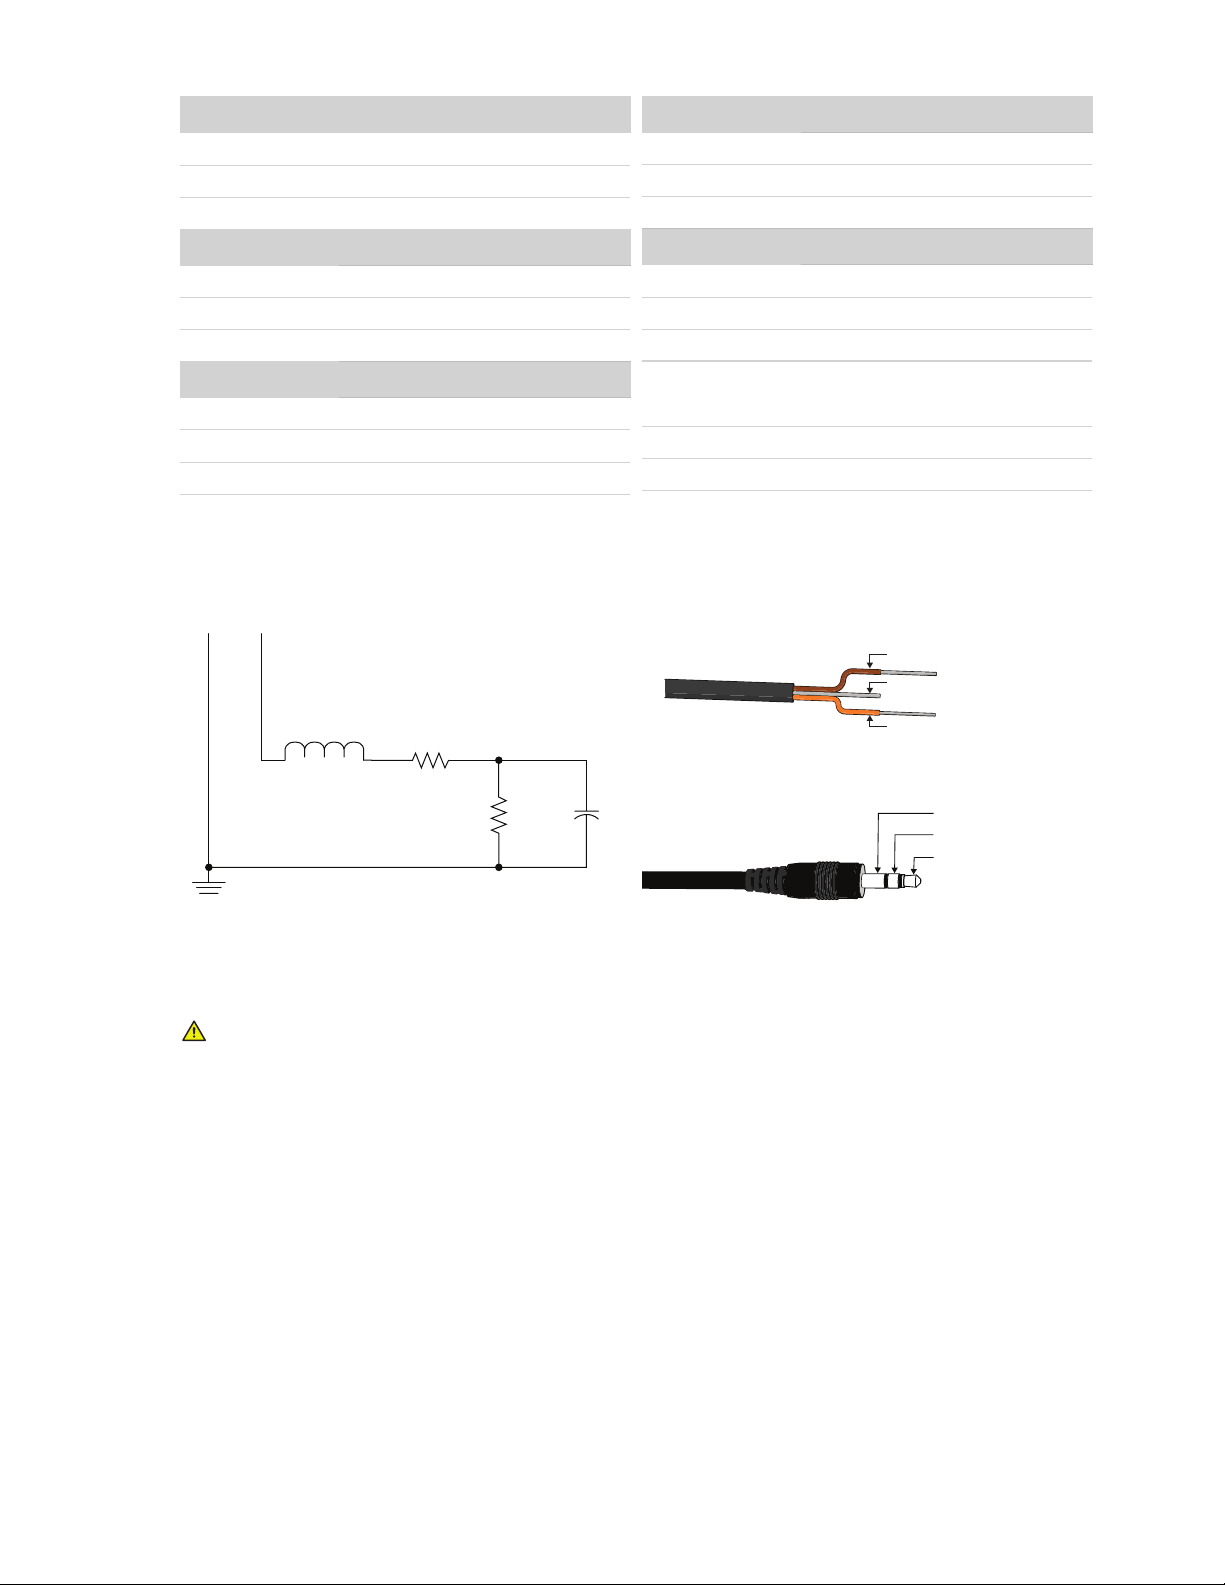
Refer to Figure 2 and Figure 3 to connect the TEROS 21 to a data logger. Figure 2 provides a low-impedance
variant of the recommended SDI-12 specification.
PIGTAIL CABLE
GND
DATA
Ground (bare)
Digital
communication (orange)
Digital communicatio
Power
GND
L1
10UH
Figure 2 Equivalent circuit diagram
R1
510
R2
100K
C1
STEREO CABLE
220PF
Figure 3 Connection types
PRECAUTIONS
METER sensors are built to the highest standards, but misuse, improper protection, or improper installation
may damage the sensor and possibly void the warranty. Before integrating sensors into a sensor network,
followthe recommended installation instructions and implement safeguards to protect the sensor from
damaging interference.
SURGE CONDITIONS
Sensors have built-in circuitry that protects them against common surge conditions. Installations in
lightning-prone areas, however, require special precautions, especially when sensors are connected to a
well-grounded third-party logger.
Read the application note Lightning surge and grounding practices on the METER website for more information.
POWER AND GROUNDING
Ensure there is sufficient power to simultaneously support the maximum sensor current drain for all the
sensors on the bus. The sensor protection circuitry may be insufficient if the data logger is improperly
powered or grounded. Refer to the data logger installation instructions. Improper grounding may affect the
sensor output as well as sensor performance.
Read the application note Lightning surge and grounding practices on the METER website for more information.
3
Page 4
TEROS 21 GEN 2
CABLES
Improperly protected cables can lead to severed cables or disconnected sensors. Cabling issues can be
caused by many factors, including rodent damage, driving over sensor cables, tripping over the cable, not
leaving enough cable slack during installation, or poor sensor wiring connections. To relieve strain on the
connections and prevent loose cabling from being inadvertently snagged, gather and secure the cable
travelling between the TEROS 21 and the data acquisition device to the mounting mast in one or more places.
Install cables in conduit or plastic cladding when near the ground to avoid rodent damage. Tie excess cable to
the data logger mast to ensure cable weight does not cause sensor to unplug.
SENSOR COMMUNICATIONS
METER digital sensors feature a serial interface with shared receive and transmit signals for communicating
sensor measurements on the data wire (Figure 3). The sensor supports two different protocols: SDI-12 and DDI
serial. Each protocol has implementation advantages and challenges. Please contact Customer Support if the
protocol choice for the desired application is not obvious.
SDI12 INTRODUCTION
SDI-12 is a standards-based protocol for interfacing sensors to data loggers and data acquisition equipment.
Multiple sensors with unique addresses can share a common 3-wire bus (power, ground, and data). Two-way
communication between the sensor and logger is possible by sharing the data line for transmit and receive
as defined by the standard. Sensor measurements are triggered by protocol command. The SDI-12 protocol
requires a unique alphanumeric sensor address for each sensor on the bus so that a data logger can send
commands to and receive readings from specific sensors.
Download the SDI-12 Specification v1.3 to learn more about the latest SDI-12 protocol.
DDI SERIAL INTRODUCTION
The DDI serial protocol is the method used by METER data loggers for collecting data from the sensor. This
protocol uses the data line configured to transmit data from the sensor to the receiver only (simplex). Typically,
the receive side is a microprocessor UART or a general-purpose I/O pin using a bitbang method to receive data.
Sensor measurements are triggered by applying power to the sensor.
INTERFACING THE SENSOR TO A COMPUTER
The serial signals and protocols supported by the sensor require some type of interface hardware to be
compatible with the serial port found on most computers (or USB-to-serial adapters). There are several
SDI-12 interface adapters available in the marketplace; however, METER has not tested any of these
interfaces and cannot make a recommendation as to which adapters work with METER sensors. METER data
loggers and the ZSC and PROCHECK handheld devices can operate as a computer-to-sensor interface for
making on-demand sensor measurements. For more information, please contact Customer Support.
METER SDI12 IMPLEMENTATION
METER sensors use a low-impedance variant of the SDI-12 standard sensor circuit (Figure 2). During the
power-up time, the sensors output some sensor diagnostic information and should not be communicated with
until the power-up time has passed. After the power-up time, the sensors are compatible with all commands
listed in the SDI-12 Specification v1.3 except for the continuous measurement commands (aR0–aR9 and aRC0–
aRC9). M, R, and C command implementations are found on pages 7–8. The aXR3 and aXR4 commands are
used by METER systems and as a result use a space delimiter, instead of a sign delimiter as required by the
SDI-12 standard.
Out of the factory, all METER sensors start with SDI-12 address 0 and print out the DDI serial startup string
during the power-up time. This can be interpreted by non-METER SDI-12 sensors as a pseudo-break condition
followed by a random series of bits.
The TEROS 21 will omit the DDI serial startup string (sensor identification) when the SDI-12 address is nonzero
or if <suppressionState> is set to 1. Changing the address to a nonzero address is recommended for this reason.
4
Page 5
TEROS 21 GEN 2
dR
SENSOR BUS CONSIDERATIONS
SDI-12 sensor buses require regular checking, sensor upkeep, and sensor troubleshooting. If one sensor goes
down, it may take down the whole bus even if the remaining sensors are functioning normally. Power cycling the
SDI-12 bus when a sensor is failing is acceptable, but METER does not recommend scheduling power cycling
events on an SDI-12 bus more than once or twice per day. Many factors influence the effectiveness of the bus
configuration. Visit metergroup.com for articles and virtual seminars containing more information.
SENSOR ERROR CODES
The TEROS 21 Gen 2 has three error codes:
• -9999 is output in place of the measured value if the sensor detects that the measurement function has been
compromised and the subsequent measurement values have no meaning
• -9992 is output in place of the measured value if the sensor detects corrupt or lost calibrations
• -9991 is output in place of the measured value if the sensor detects insufficient voltage to perform the
measurement
SDI12 CONFIGURATION
Table1 lists the SDI-12 communication configuration.
Table1 SDI-12 communication configuration
Baud Rate 1,200
Start Bits 1
Data Bits 7 (LSB first)
Parity Bits 1 (even)
Stop Bits 1
Logic Inverted (active low)
SDI12 TIMING
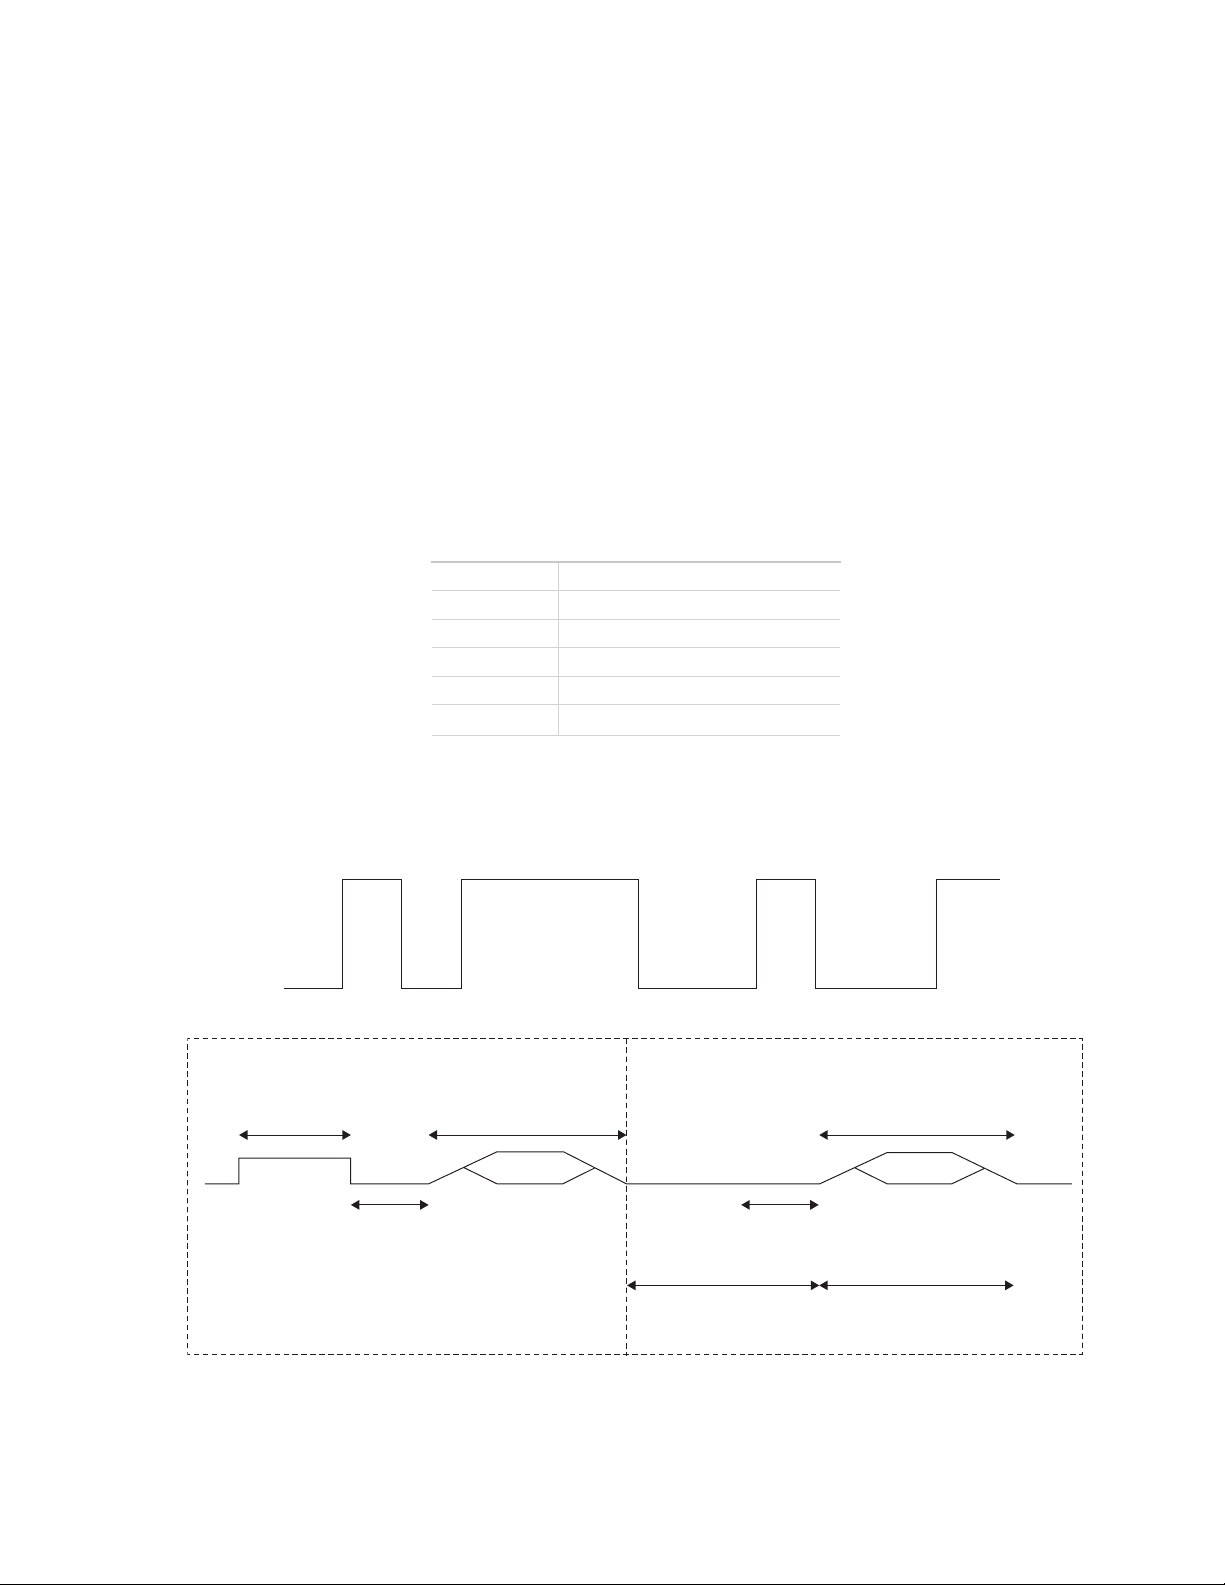
All SDI-12 commands and responses must adhere to the format in Figure 4 on the data line. Both the
command and response are preceded by an address and terminated by a carriage return and line feed
combination (<CR><LF>) and follow the timing shown in Figure 5.
START STOPD0 D1 D2 D3 D4 D5 D6 EP
Figure 4 Example SDI-12 transmission of the character 1 (0x31)
SENSORDATA LOGGER
Break
(at least 12 ms)
(at least 8.33 ms)
Comman
Marking
within 15 ms
*Maximum time is dependent upon the amount of data returned for the command sent.
Marking
(at least 8.33 ms)
esponse
Maximum time*Sensor must respond
Figure 5 Example data logger and sensor communication
5
Page 6
TEROS 21 GEN 2
COMMON SDI12 COMMANDS
This section includes tables of common SDI-12 commands that are often used in an SDI-12 system and the
corresponding responses from METER sensors.
IDENTIFICATION COMMAND aI!
The Identification command can be used to obtain a variety of detailed information about the connected
sensor. An example of the command and response is shown in Example 1, where the command is in bold and
the response follows the command.
Example 1 1I!113METER ␣ ␣ ␣TER21 ␣ 337631800001
Fixed
Parameter
1I!
1
13
METER␣ ␣ ␣
TER21 ␣
389
631800001
NOTE: In the event that the fixed length is longer than the parameter, the trailing characters will be populated with space characters.
Character
Length Description
3
1
2 Indicates that the target sensor supports SDI-12 Specification v1.3.
8
6
3
≤13,
variable
Data logger command.
Request to the sensor for information from sensor address 1.
Sensor address.
Prepended on all responses, this indicates which sensor on the bus is returning the
following information.
Vendor identification string.
(METER and three spaces ␣ ␣ ␣)
Sensor model string.
This string is specific to the sensor type.
For the TEROS 21, the string is TER21.
Sensor version.
This number divided by 100 is the METER sensor version
(e.g., 389 is version 3.89).
Sensor serial number.
This is a variable length field. It may be omitted for older sensors.
CHANGE ADDRESS COMMAND aAB!
The Change Address command is used to change the sensor address to a new address. All other commands
support the wildcard character as the target sensor address except for this command. All METER sensors
have a default address of 0 (zero) out of the factory. Supported addresses are alphanumeric (i.e., a–z, A–Z, and
0–9). An example output from a METER sensor is shown in Example 2, where the command is in bold and the
response follows the command.
Example 2 1A0!0
Fixed
Character
Parameter
1A0!
0
Length Description
4
1
Data logger command.
Request to the sensor to change its address from 1 to a new address of 0.
New sensor address.
For all subsequent commands, this new address will be used by the targetsensor.
ADDRESS QUERY COMMAND (?!)
While disconnected from a bus, the Address Query command can be used to determine which sensor is
currently being communicated with. Sending this command over a bus will cause a bus contention where all
the sensors will respond simultaneously and corrupt the data line. This command is helpful when trying to
isolate a failed sensor. Example 3 shows an example of the command and response, where the command is in
bold and the response follows the command. The question mark (?) is a wildcard character that can be used in
place of the address with any command except the Change Address command.
6
Page 7
TEROS 21 GEN 2
Example 3 ?!0
Fixed
Character
Parameter
?!
0
Length Description
2
1
Data logger command.
Request for a response from any sensor listening on the data line.
Sensor address.
Returns the sensor address to the currently connected sensor.
COMMAND IMPLEMENTATION
The following tables list the relevant Measurement (M), Verification (V), Extended (X), Continuous (R), and
Concurrent (C) commands and subsequent Data (D) commands, when necessary.
MEASUREMENT COMMANDS IMPLEMENTATION
Measurement (M) commands are sent to a single sensor on the SDI-12 bus and require that subsequent Data
(D) commands are sent to that sensor to retrieve the sensor output data before initiating communication with
another sensor on the bus.
Please refer to Table2 and for an explanation of the command sequence and see Table9 for an explanation of
response parameters.
Table2 aM! measurement command sequence
Command Response
This command reports instantaneous values.
aM! atttn
aD0! a-<matricPotential>±<temperature>
NOTE: The measurement and corresponding data commands are intended to be used back to back. After a measurement command is
processed by the sensor, a service request a <CR><LF> is sent from the sensor signaling the measurement is ready. Either wait until ttt
seconds have passed or wait until the service request is received before sending the data commands. See the SDI-12 Specifications v1.3
document for more information.
CONCURRENT MEASUREMENT COMMANDS IMPLEMENTATION
Concurrent Measurement (C) commands are typically used with sensors connected to a bus. C commands
for this sensor deviate from the standard C command implementation. First, send the C command, wait the
specified amount of time detailed in the C command response, and then use D commands to read its response
prior to communicating with another sensor.
Please refer to Table3 for an explanation of the command sequence and see Table9 for an explanation of
response parameters.
Table3 aC! measurement command sequence
Command Response
This command reports instantaneous values.
aC! atttnn
aD0! a-<matricPotential>±<temperature>
NOTE: This command does not adhere to the SDI-12 concurrent command requirements. See METER SDI-12 Implementation for
moreinformation.
NOTE: The measurement and corresponding data commands are intended to be used back to back. After a measurement command is
processed by the sensor, a service request a <CR><LF> is sent from the sensor signaling the measurement is ready. Either wait until ttt
seconds have passed or wait until the service request is received before sending the data commands. See the SDI-12 Specifications v1.3
document for more information.
VERIFICATION COMMAND IMPLEMENTATION
The Verification (V) command is intended to give users a means to determine information about the current
state of the sensor. The V command is sent first, followed by D commands to read the response.
7
Page 8
TEROS 21 GEN 2
Table4 aV! measurement command sequence
Command Response
aV! atttnn
aD0! a+<meta>
EXTENDED COMMAND IMPLEMENTATION
Extended (X) commands provide sensors with a means of performing manufacturer-specific functions.
Additionally, the extended commands are utilized by METER systems and use a different response format than
standard SDI-12 commands. X commands are required to be prefixed with the address and terminated with an
exclamation point. Responses are required to be prefixed with the address and terminated with <CR><LF>.
METER implements the following X commands: aXRx! to trigger a sensor measurement and return the data
automatically after the readings are completed without needing to send additional commands and aXO! (with
capital O) to suppress the DDI string.
Please refer to Table5 through Table7 for an explanation of the command sequence and see Table9 for an
explanation of response parameters.
Table5 aXO! measurement command sequence
Command Response
aXO! a<suppressionState>
aXO<suppressionState>! aOK
Table6 aXR3! measurement command sequence
Command Response
aXR3! a<TAB><matricPotential> <temperature><CR><sensorType><Checksum><CRC>
Table7 aXR4! measurement command sequence
Command Response
aXR4! a<TAB><matricPotential> <temperature><CR><sensorType><Checksum><CRC>
CONTINUOUS MEASUREMENT COMMANDS IMPLEMENTATION
Continuous Measurement (R) commands trigger a sensor measurement and return the data automatically
after the readings are completed without needing to send a D command.
Please refer to Table8 for an explanation of the command sequence and see Table9 for an explanation of
response parameters.
Table8 aR0! measurement command sequence
Command Response
This command reports instantaneous values.
aR0! a-<matricPotential>±<temperature>
NOTE: This command does not adhere to the SDI-12 response timing. See METER SDI-12 Implementation for moreinformation.
PARAMETERS
Table9 lists the parameters, unit measurement, and a description of the parameters returned in command
responses for TEROS 21.
8
Page 9
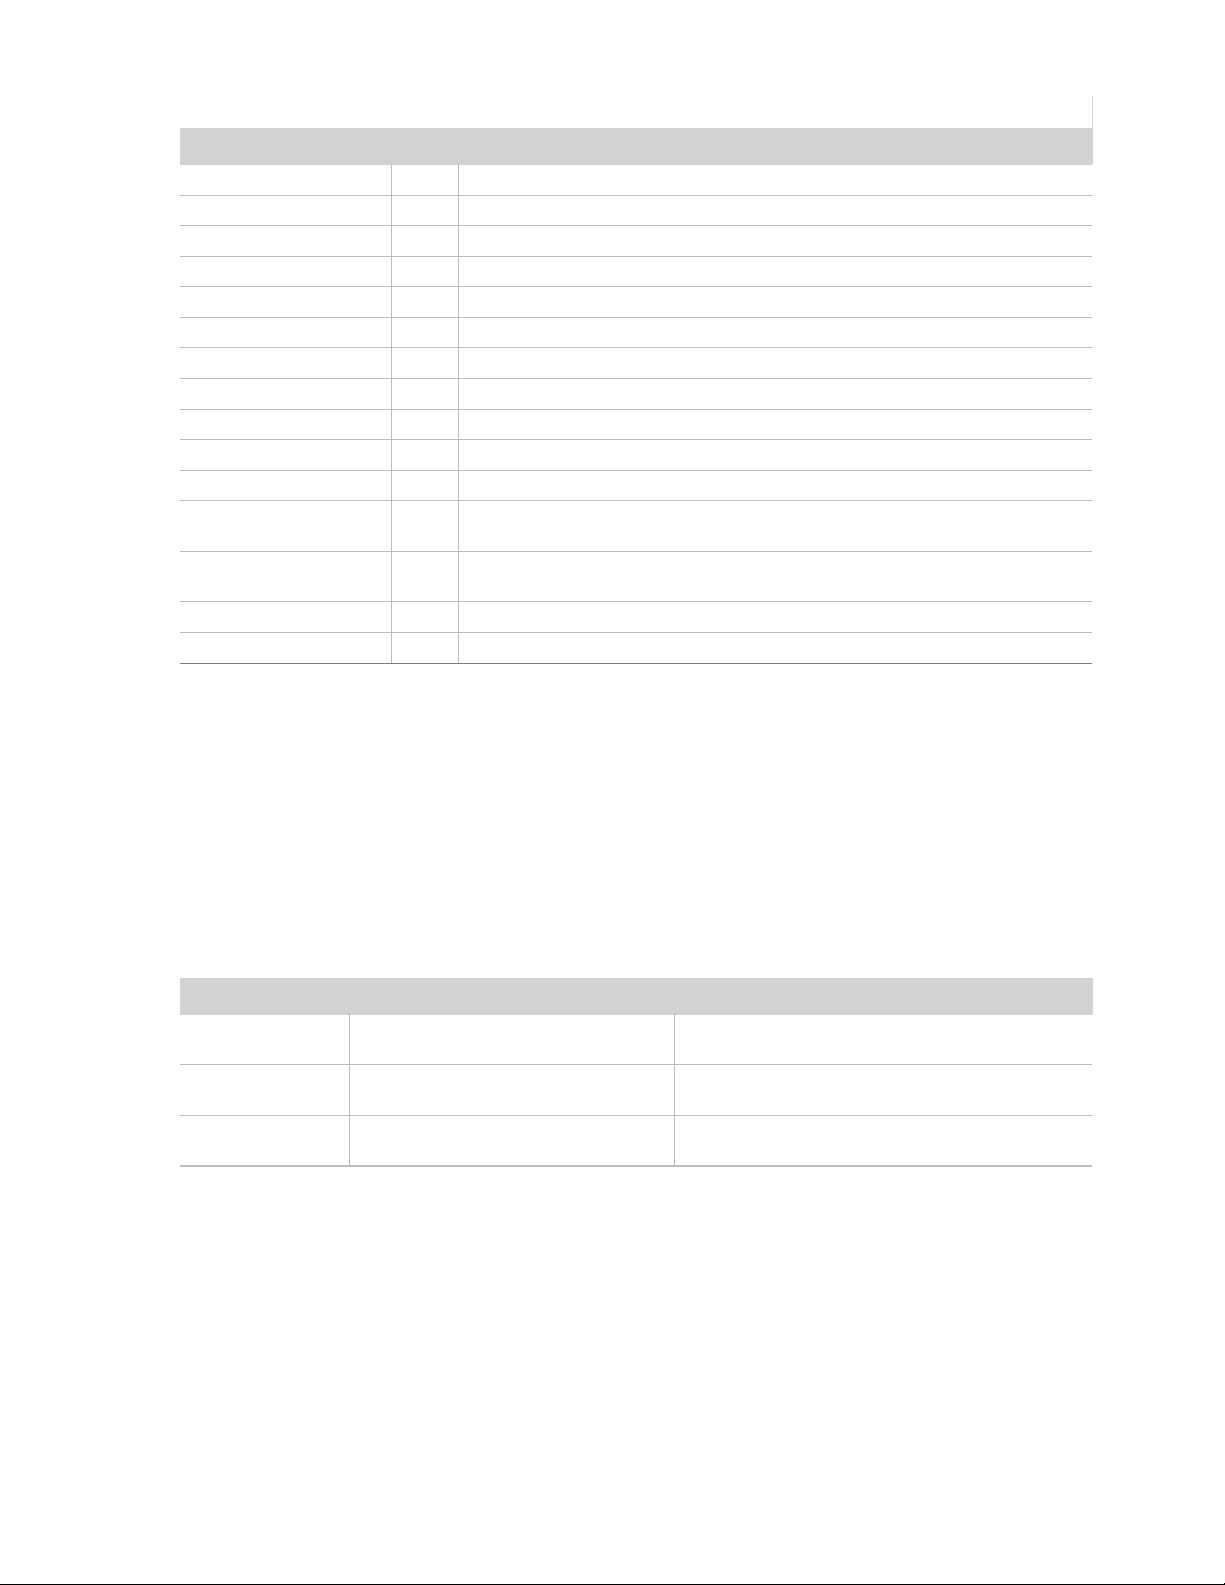
Table9 Parameter descriptions
Parameter Unit Description
±
a
n
nn
ttt
<TAB>
<CR>
<LF>
<matricPotential>
<temperature>
<meta>
<suppressionState>
<sensorType>
<Checksum>
<CRC>
— Positive or negative sign denoting sign of the next value
— SDI-12 address
— Number of measurements (fixed width of 1)
— Number of measurements with leading zero if necessary (fixed width of 2)
s Maximum time measurement will take (fixed width of 3)
— Tab character
— Carriage return character
— Line feed character
kPa Matric potential
°C Air temperature
— Auxiliary sensor information. See Table10.
O: DDI unsuppressed
—
1: DDI suppressed
ASCII character denoting the sensor type
—
For TEROS 21, the character is k
— METER serial checksum
— METER 6-bit CRC
TEROS 21 GEN 2
SENSOR METADATA VALUE
The sensor metadata value contains information to help alert users to sensor-identified conditions that may
compromise optimal sensor operation. The output of the aV! aD0! sequence will output a <meta> integer value.
This integer represents a binary bitfield, with each individual bit representing an error flag.
Table10 lists the possible error flags that can be set by the TEROS 21. If multiple error flags are set, the sensor
metadata integer value will be the sum of the individual values. To decode an integer value not explicitly
in Table10, find the largest error flag value that will fit in the integer value and accept that error as being
present. Then, subtract that error flag value from the integer value and repeat the process on the remainder
until the result is zero. For example, a sensor metadata integer value of 384 is the sum of the individual error
flag values 256+128, so this sensor has corrupt firmware and a corrupt or lost sensor calibration.
Table10 Error flag values and issue resolution
Error Flag Value Issue Present Resolution
64
128 Sensor firmware is corrupt
256 Sensor calibrations lost or corrupted
Sensor thermistor is broken and sensor is
using a backup measurement
Contact Customer Support to replace sensor
Contact Customer Support for instructions on
reloading firmware
Contact Customer Support for instructions on
reloading sensor calibrations
DDI SERIAL COMMUNICATION
The DDI serial communications protocol is ideal for systems that have dedicated serial signaling lines for each
sensor or use a multiplexer to handle multiple sensors. The serial communications are compatible with many
TTL serial implementations that support active-high logic levels using 0.0- to 3.6-VDC signal levels. When the
sensor is first powered, it automatically makes measurements of the integrated transducers then outputs a
response over the data line. Systems using this protocol control the sensor excitation to initiate data transfers
from the sensor. This protocol is subject to change as METER improves and expands the line of digital sensors
and dataloggers.
TEROS 21 will omit the DDI serial startup string when the SDI-12 address is nonzero.
NOTE: Out of the factory, all METER sensors start with SDI-12 address 0 and print out the startup string when power cycled. On
TEROS21 Gen 2 sensors with firmware version 3.37 and newer the startup string is omitted when the address is nonzero.
9
Page 10
TEROS 21 GEN 2
Measurement
DDI SERIAL TIMING
Table11 lists the DDI serial communication configuration.
Table11 DDI serial communication configuration
Baud Rate 1,200
Start Bits 1
Data Bits 8 (LSB first)
Parity Bits 0 (none)
Stop Bits 1
Logic Standard (active high)
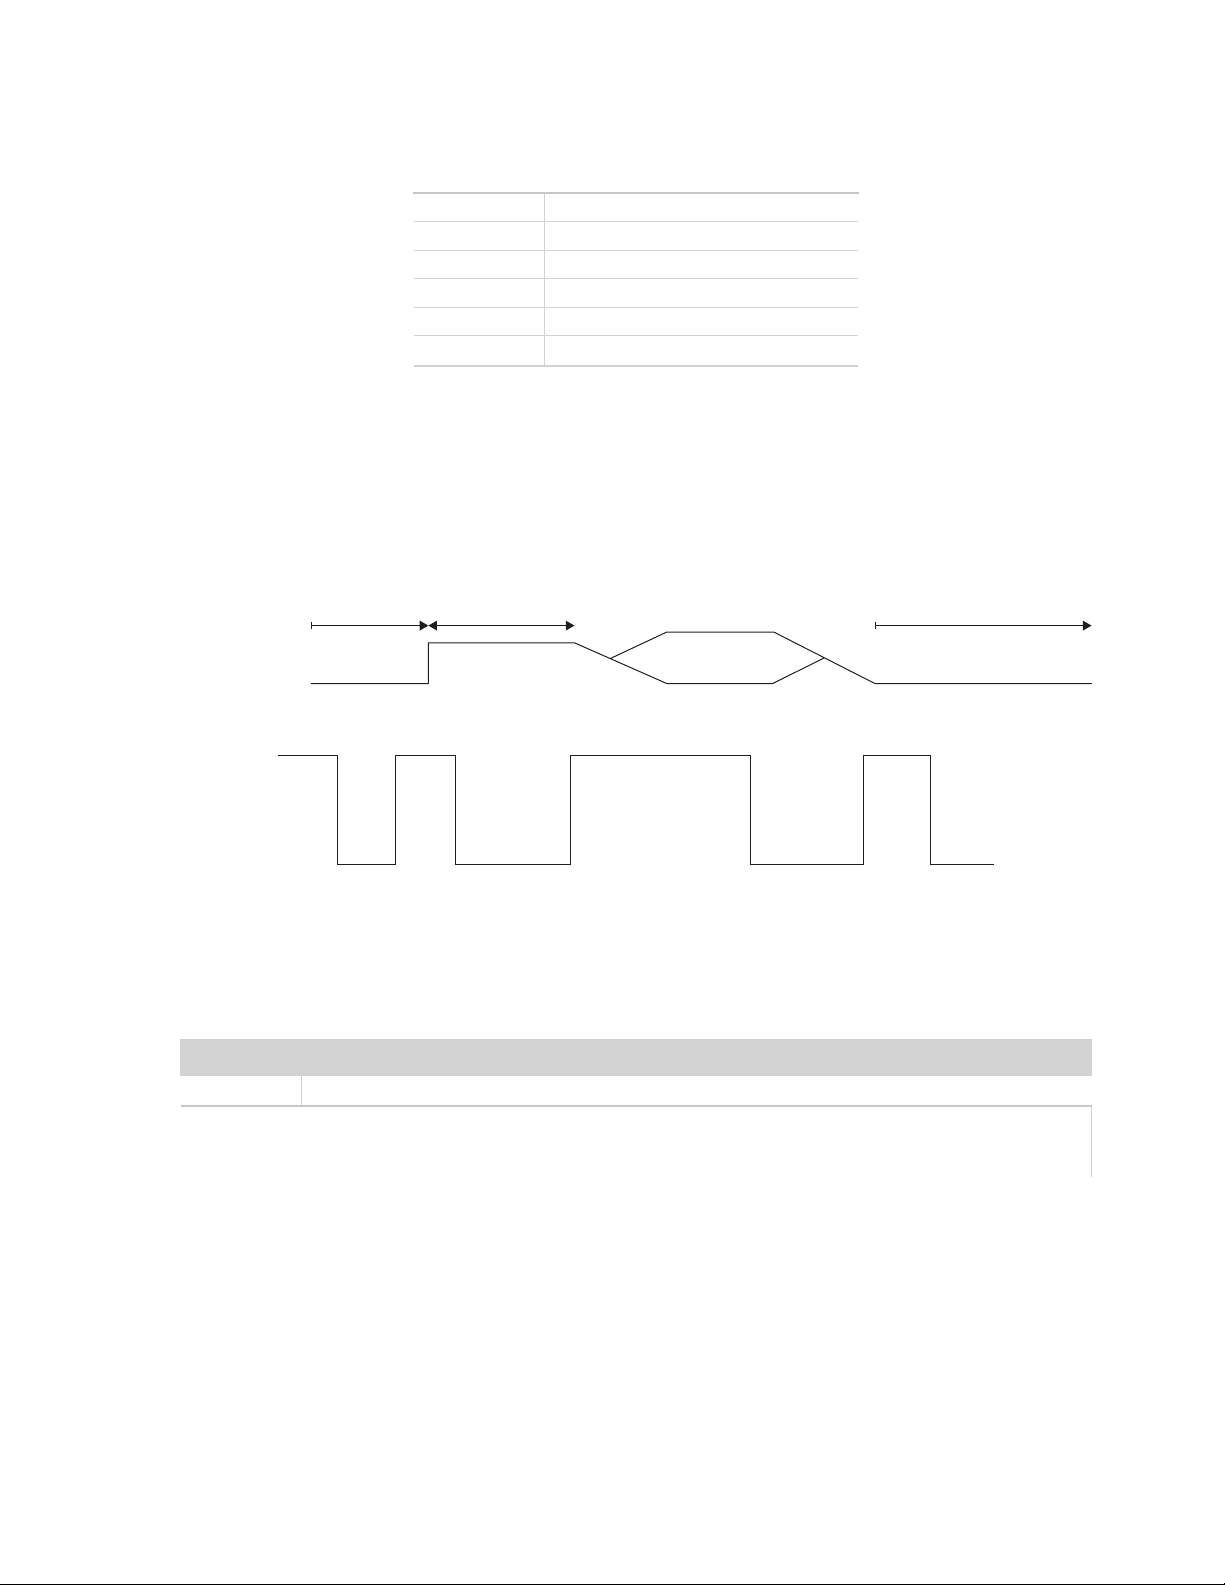
At power up, the sensor will pull the data line high within 100 ms to indicate that the sensor is taking a reading
(Figure 6). When the reading is complete, the sensor begins sending the serial signal out the data line adhering
to the format shown in Figure 7. Once the data is transmitted, the sensor goes into SDI-12 communication
mode. To get another serial signal, the sensor must be power cycled.
NOTE: Sometimes the signaling from the sensor can confuse typical microprocessor UARTs. The sensor holds the data line low while
taking measurements. The sensor raises the line high to signal the logger that it will send a measurement. Then the sensor may take some
additional measurements before starting to clock out the first data byte starting with a typical start bit (low). Once the first start bit is sent,
typical serial timing is valid; however, the signal transitions before this point are not serial signaling and may be misinterpreted by theUART.
Up to 100 ms
duration
DDI serial
SDI-12 ready
Power applied
Figure 6 Data line DDI serial timing
START STOPD0 D1 D2 D3 D4 D5 D6 D7
Figure 7 Example DDI serial transmission of the character 9 (0x39)
DDI SERIAL RESPONSE
Table12 details the DDI serial response.
Table12 DDI serial response
COMMAND RESPONSE
-
NOTE: There is no actual command. The response is returned automatically upon power up.
The values in this command are space delimited. As such,a+ sign is not assigned between values and a – sign is only present if the value
is negative.
<TAB><matricPotential> <temperature><CR><sensorType><Checksum><CRC>
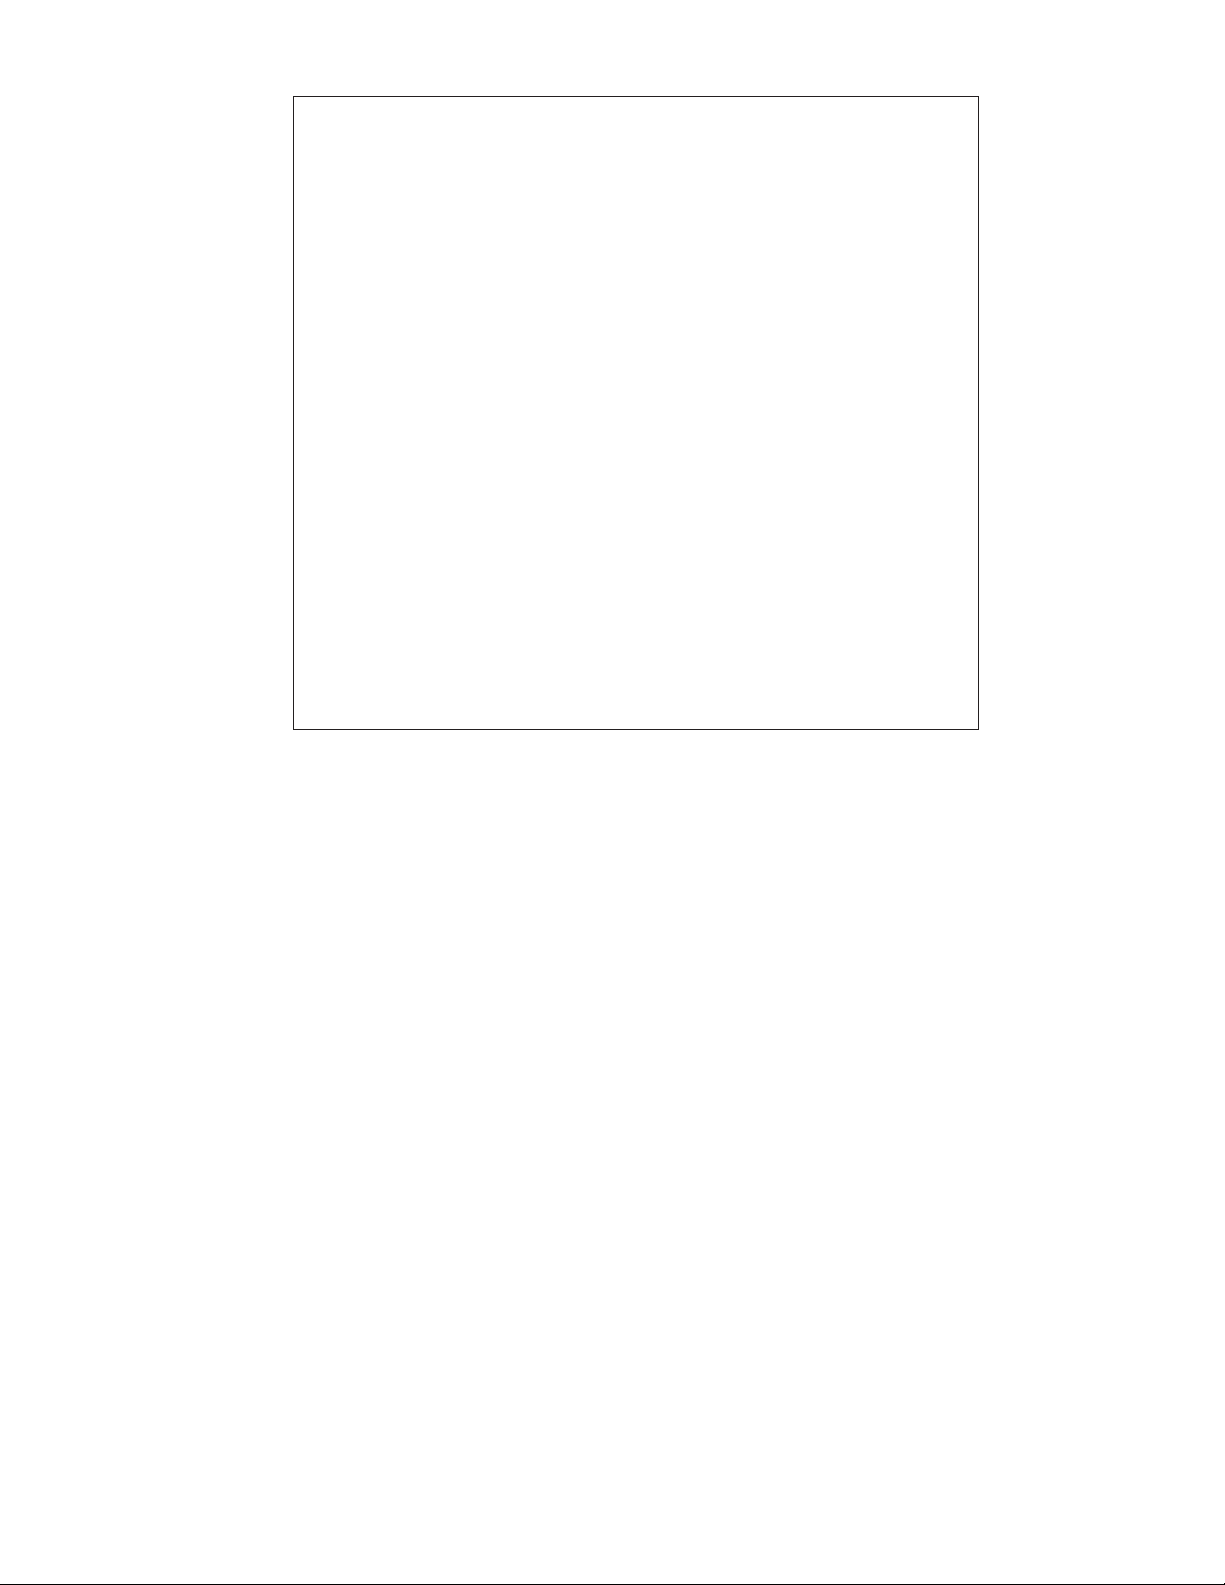
DDI SERIAL CHECKSUM
The legacy checksum is computed from the start of the transmission to the sensor identification character.
These checksums are used in the continuous commands R3 and R4 as well as the DDI serial response.
Legacy checksum example input is <TAB>-34.8 22.3<CR>k@l and the resulting checksum output is @.
10
Page 11
TEROS 21 GEN 2
uint8_t LegacyChecksum(const char * response)
{
uint16_t length;
uint16_t i;
uint16_t sum = 0
// Finding the length of the response string
length = strlen(response);
// Adding characters in the response together
for( i = 0; i < length; i++ )
{
sum += response[i];
if(response[i] == '\r')
{
//Found the beginning of the metadata section of the response
break;
}
}
// Include the sensor type into the checksum
sum += response[++i};
// Convert checksum to a printable character
sum = sum % 64 + 32;
return sum;
}
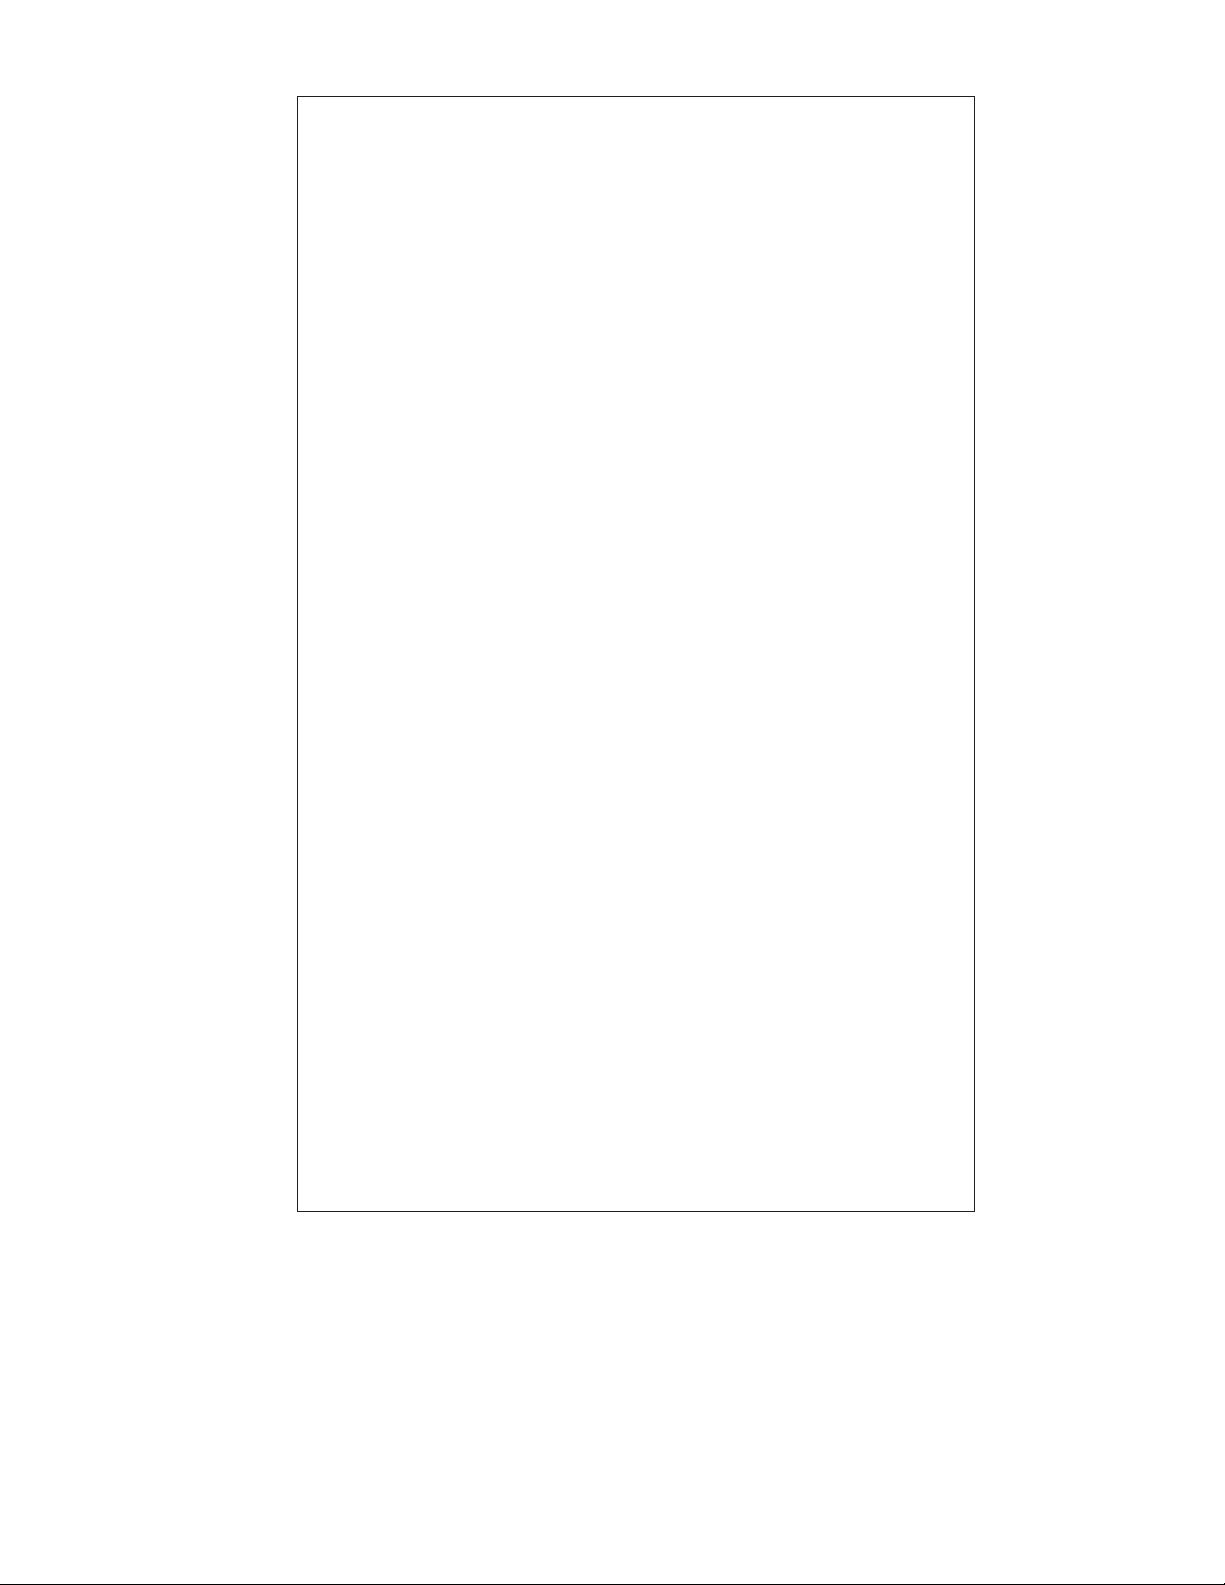
The more robust CRC6, if available, utilizes the CRC-6-CDMA2000-A polynomial with the value 48 added to the
results to make this a printable character and is computed from the start of the transmission to the legacy
checksum character.
CRC6 checksum example input is <TAB>-34.8 22.3<CR>k@l and the resulting checksum output is l (lowercase L).
11
Page 12
TEROS 21 GEN 2
uint8_t CRC6_offset(const char * buffer)
{
uint16_t byte;
uint16_t i;
uint16_t bytes;
uint8_t bit;
uint8_t crc = 0xfc; // Set upper 6 bits to 1’s
// Calculate total message length-updated once the metadata section
is found
bytes = strien(buffer)
// Loop through all the bytes in the buffer
for(byte = 0; byte < bytes; byte++)
{
// Get the next byte in the buffer and XOR it with the crc
crc ^= buffer[byte];
// Loop through all the bits in the current byte
for(bit = 8; bit > 0; bit--)
{
// If the uppermost bit is a 1...
if(crc & 0x80)
{
// Shift to the next bit and XOR it with a polynomial
crc = (crc << 1) ^ 0x9c;
}
else
{
// Shift to the next bit
crc = crc << 1;
}
}
if(buffer[byte] == '\r')
{
// Found the beginning of the metadata section of the response
// Both sensor type and legacy checksum are part of the crc6
// This requires only two more iterations of the loop so reset
// "bytes"
// Bytes is incremented at the beginning of the loop, so 3 is added
bytes = byte + 3;
}
}
// Shift upper 6 bits down for crc
crc = (crc >> 2);
// Add 48 to shift crc to printable character avoiding \r \n and !
return (crc + 48);
}
12
Page 13
TEROS 21 GEN 2
CUSTOMER SUPPORT
NORTH AMERICA
Customer service representatives are available for questions, problems, or feedback Monday through Friday,
7:00 am to 5:00 pm Pacific time.
Email: [email protected]
Phone: +1.509.332.5600
Fax: +1.509.332.5158
Website: metergroup.com
EUROPE
Customer service representatives are available for questions, problems, or feedback Monday through Friday,
8:00 to 17:00 Central European time.
Email: [email protected]
Phone: +49 89 12 66 52 0
Fax: +49 89 12 66 52 20
Website: metergroup.de
If contacting METER by email, please include the following information:
Name
Address
Phone number
Email address
Instrument serial number
Description of problem
NOTE: For products purchased through a distributor, please contact the distributor directly for assistance.
REVISION HISTORY
The following table lists document revisions.
Revision Date Compatible Firmware Description
00 6.30.2020 5.00 Initial release for TEROS 21 Gen 2
13
 Loading...