

Page 1
EN29F040A
4 Megabit (512K x 8-bit) Flash Memory
FEATURES
EN29F040A
• 5.0V operation for read/write/erase
operations
• F ast Read Access Time
- 45ns, 55ns, 70ns, and 90ns
• Sector Architecture:
- 8 uniform sectors of 64Kbytes each
- Supports full chip erase
- Individual sector erase supported
- Sector protection:
Hardware locking of sectors to prevent
program or erase operations within
individual sectors
• High performance program/erase speed
- Byte program time: 10µs typical
- Sector erase time: 500ms typical
- Chip erase time: 3.5s typical
• Low Standby Current
- 1µA CMOS standby current-typical
- 1mA TTL standby current
• Low Power Active Current
- 30mA active read current
- 30mA program/erase current
• JEDEC Standard program and erase
commands
• JEDEC standard
bits feature
• Single Sector and Chip Erase
• Sector Unprotect Mode
• Embedded Erase and Program Algorithms
• Erase Suspend / Resume modes:
Read and program another Sector during
Erase Suspend Mode
• 0.23 µm triple-metal double-poly
triple-well CMOS Flash Technology
• Low Vcc write inhibit < 3.2V
• 100K endurance cycle
• Package Options
- 32-pin PDIP
- 32-pin PLCC
- 32-pin TSOP (Type 1)
• Commercial and Industrial Temperature
Ranges
polling and toggle
DATA
GENERAL DESCRIPTION
The EN29F040A is a 4-Megabit, electrically erasable, read/write non-volatile flash memory.
Organized into 512K words with 8 bits per word, the 4M of memory is arranged in eight uniform
sectors of 64Kbytes each. Any byte can be programmed typically in 10µs. The EN29F040A
features 5.0V voltage read and write operation, with access times as fast as 45ns to eliminate the
need for WAIT states in high-performance microprocessor systems.
The EN29F040A has separate Output Enable (
controls, which eliminate bus contention issues. This device is designe d to allow eith er sing le (or
multiple) Sector or full chip erase operation, where each Sector can be individually protected against
program/erase operations or temporarily unprotected to erase or program. The device can sustain a
minimum of 100K program/erase cycles on each Sector.
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
), Chip Enable (CE), and Write Enable (
OE
1
Rev. B, Issue Date: 2004/04/01
WE
)
Page 2
EN29F040A
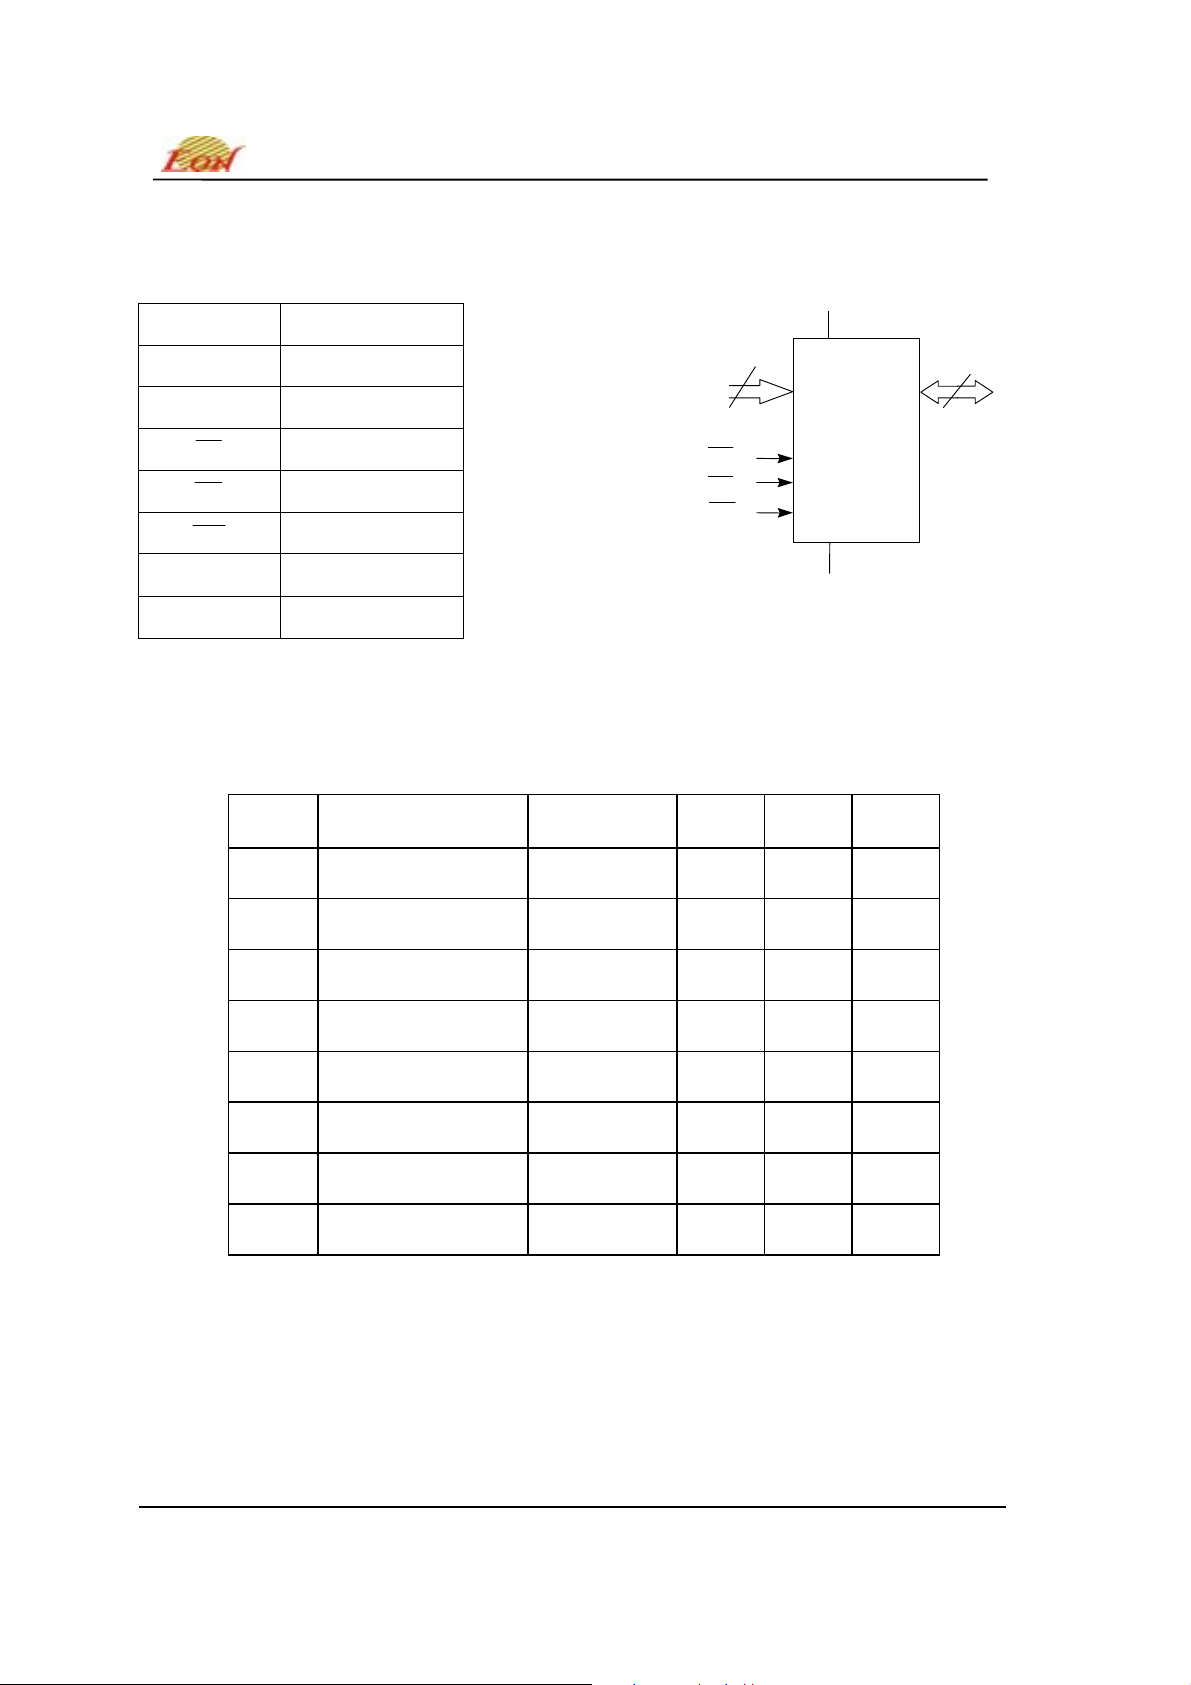
TABLE 1. PIN DESCRIPTION FIGURE 1. LOGIC DIAGRAM
Pin Name Function
A0-A18 Addresses
DQ0-DQ7 Data Inputs/Outputs
CE
OE
WE
Vcc
Vss Ground
Chip Enable
Output Enable
Write Enable
Supply Voltage
(5V ± 10% )
TABLE 2. SECTOR ARCHITECTURE
18
CE
OE
WE
Vcc
EN29F040A
Vss
8
DQ0 - DQ7A0 - A18
Sector ADDRESSES
7 70000h - 7FFFFh 64 1 1 1
6 60000h - 6FFFFh 64 1 1 0
5 50000h – 5FFFFh 64 1 0 1
4 40000h – 4FFFFh 64 1 0 0
3 30000h – 3FFFFh 64 0 1 1
2 20000h - 2FFFFh 64 0 1 0
1 10000h - 1FFFFh 64 0 0 1
0 00000h - 0FFFFh 64 0 0 0
SIZE (Kbytes) A18 A17 A16
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
2
Rev. B, Issue Date: 2004/04/01
Page 3
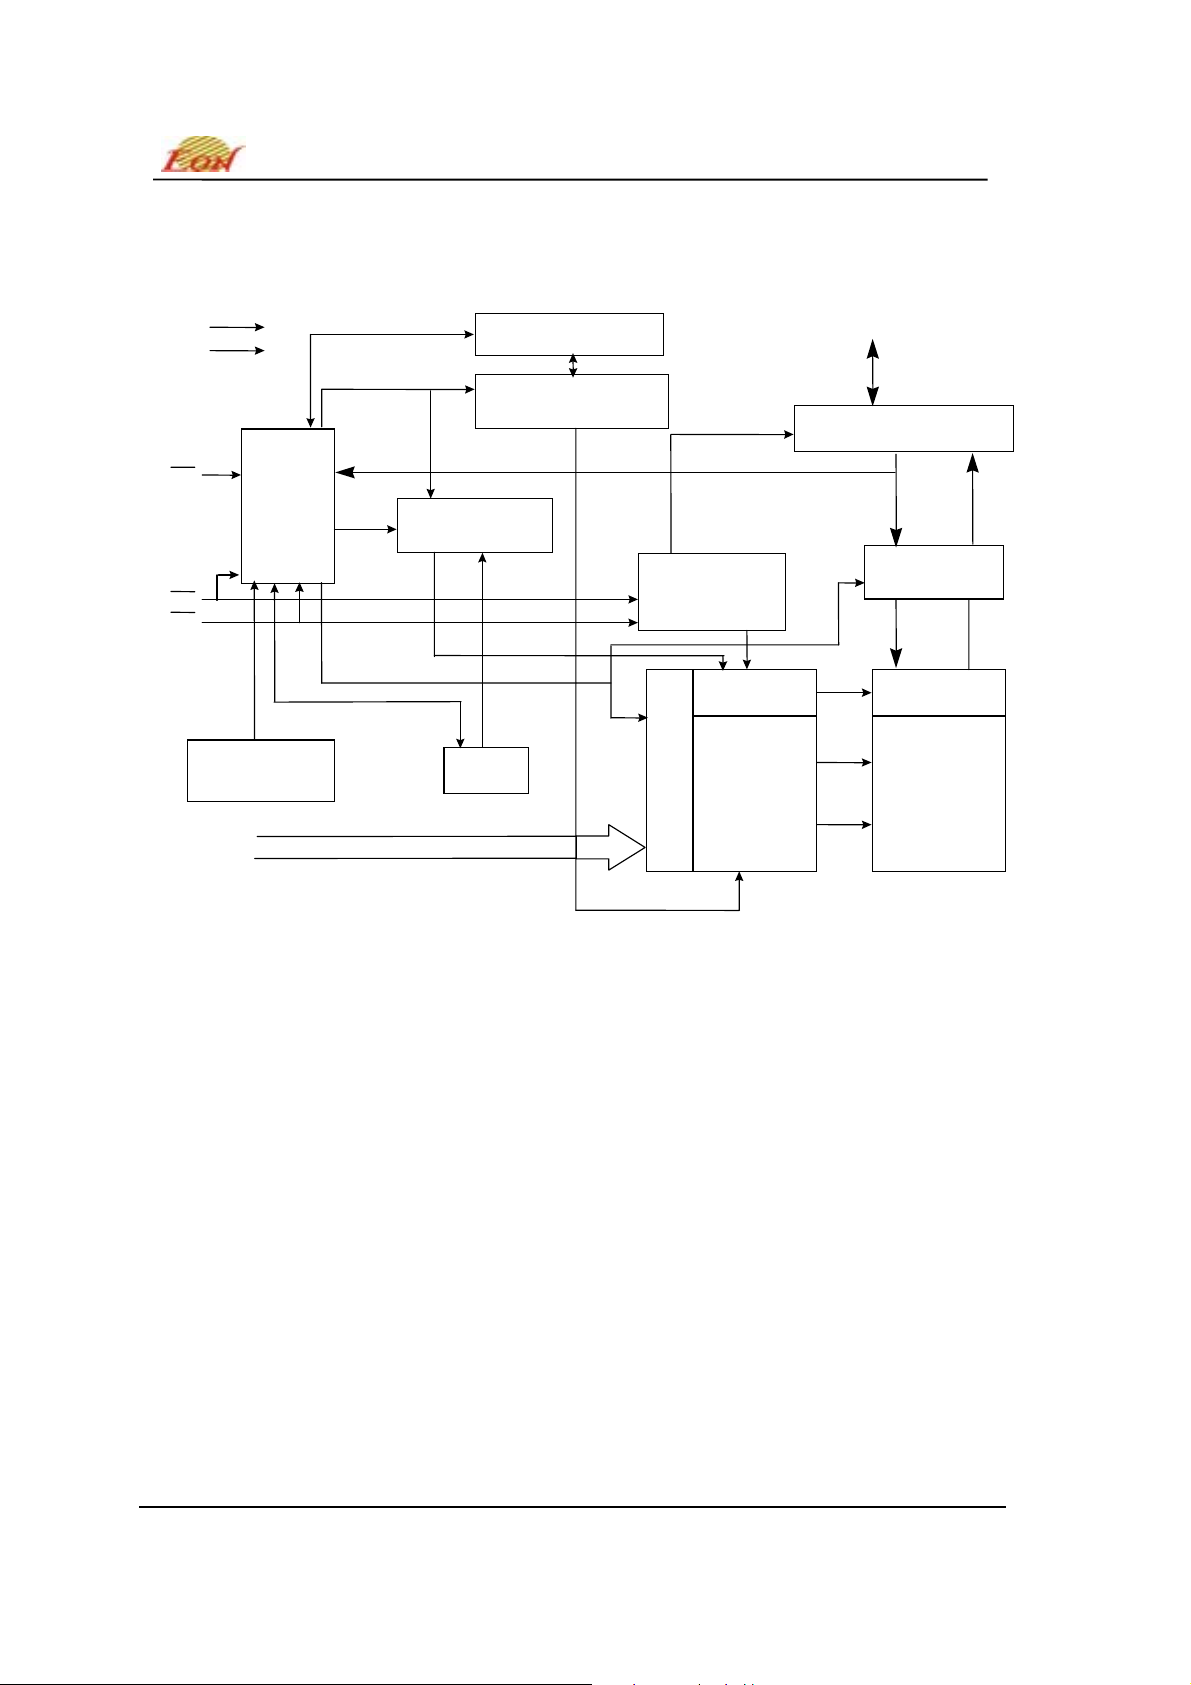
BLOCK DIAGRAM
Vcc
Vss
State
WE
CE
OE
Control
Command
Register
Block Protect Switches
Erase Voltage Generator
Program Voltage
Generator
Chip Enable
Output Enable
Logic
EN29F040A
DQ0-DQ7
Input/Output Buffers
STB
Data Latch
A0-A18
Y-Decoder
Address Latch
STB
TimerVcc Detector
X-Decoder
Y-Gating
Cell Matrix
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
3
Rev. B, Issue Date: 2004/04/01
Page 4
EN29F040A
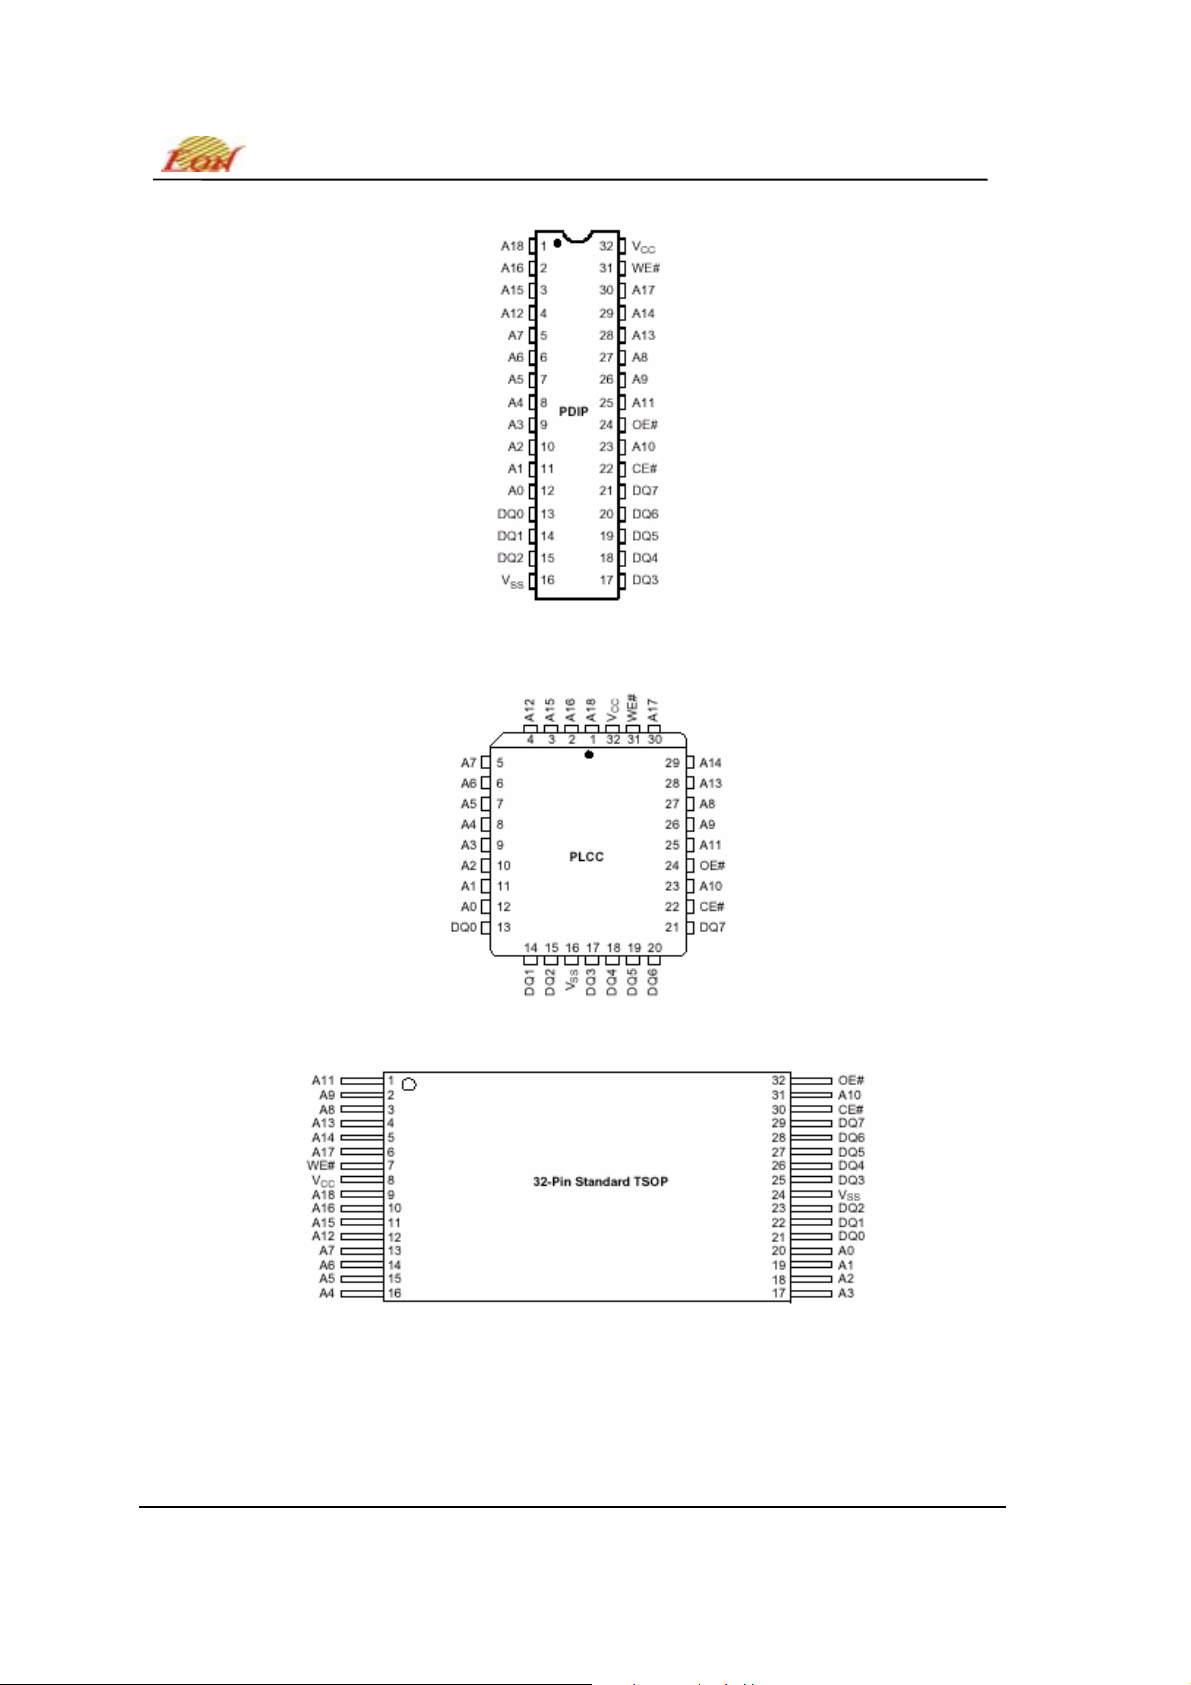
FIGURE 2. PDIP
FIGURE 3. PLCC
FIGURE 4. TSOP
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
4
Rev. B, Issue Date: 2004/04/01
Page 5
EN29F040A
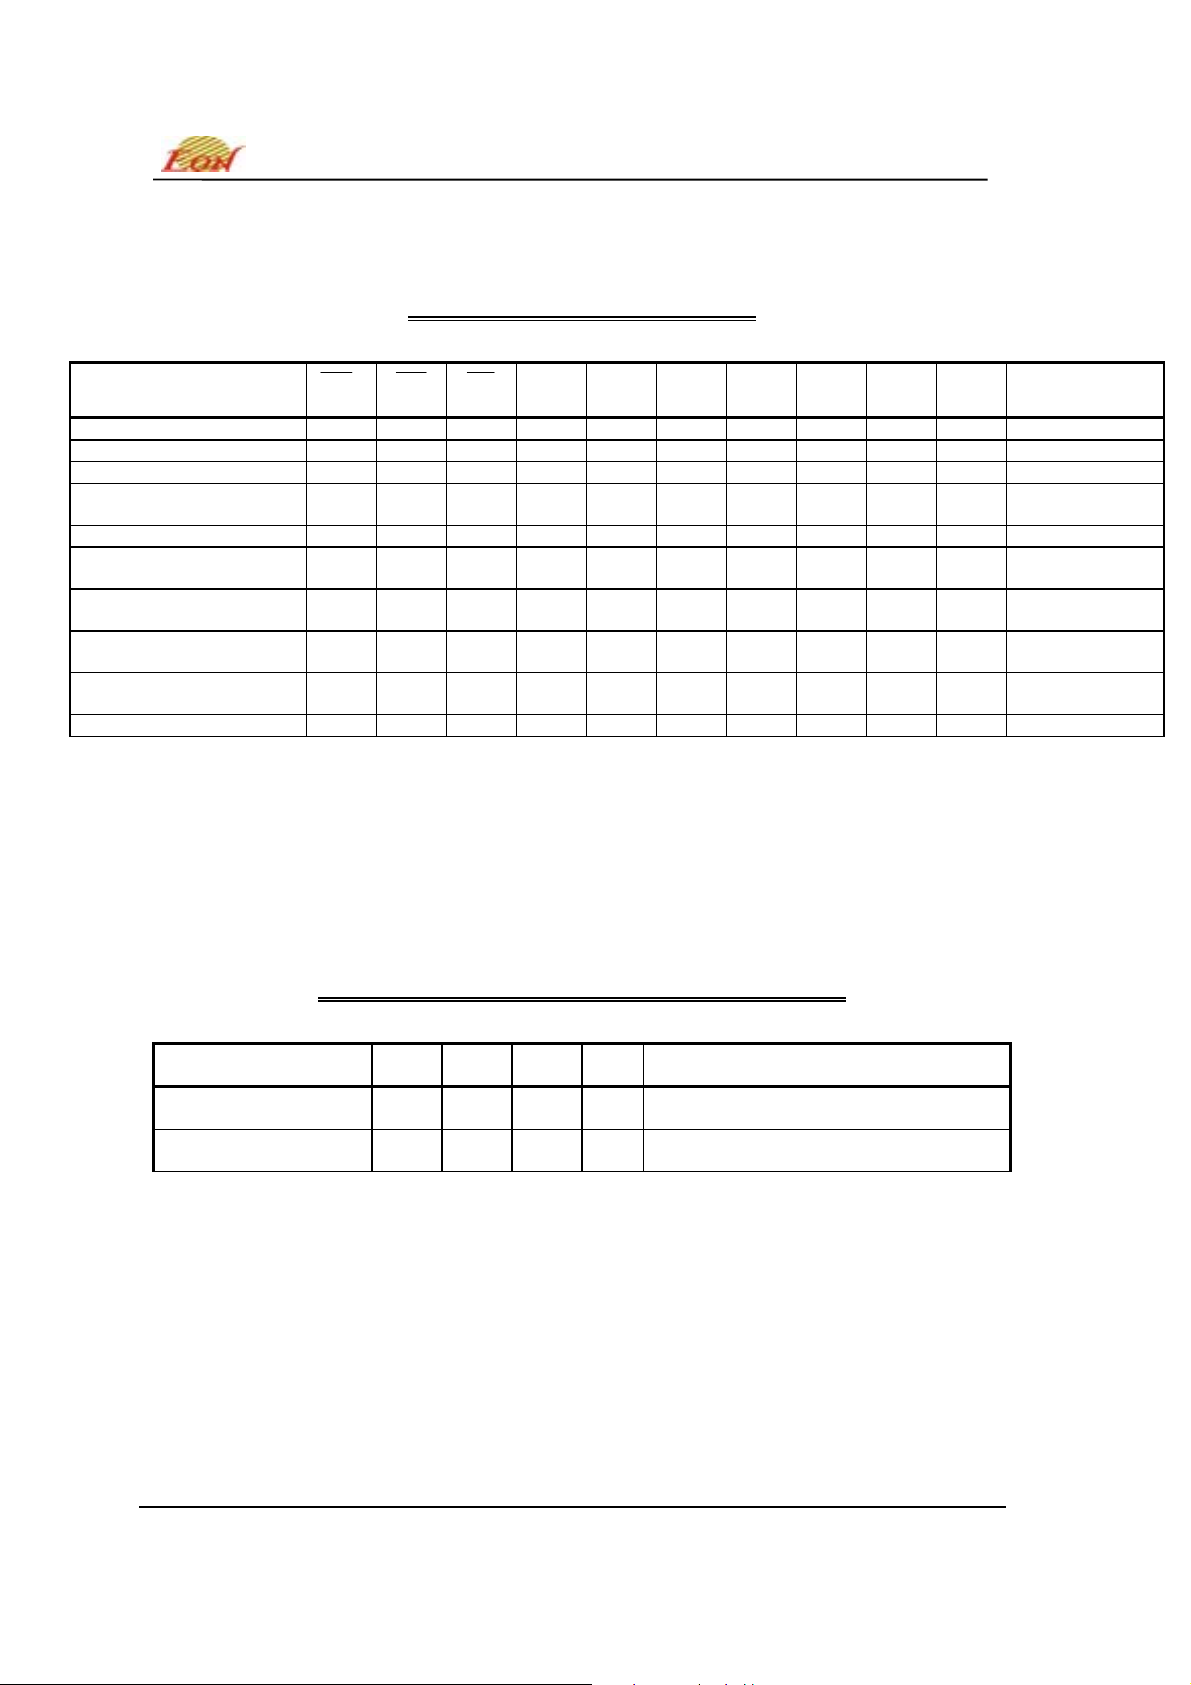
TABLE 3. OPERATING MODES
4M FLASH USER MODE TABLE
USER MODE
STANDBY H X X X X X X X X X HI-Z
READ L H L A9 A8 A6 A5 A1 A0 Ax/y DQ (0-7)
OUTPUT DISABLE L H H X X X X X X X HI-Z
READ
MANUFACTURE ID
READ DEVICE ID L H L VID L/H L X L H X DEVICE ID (T/B)
VERIFY SECTOR
PROTECTION
SECTOR
PROTECTION
VERIFY SECTOR
UNPROTECTION
SECTOR
UNPROTECTION
WRITE L L H A9 A8 A6 A5 A1 A0 Ax/y DIN (0-7)
NOTES:
1) L = V
2) X = Don’t care, either V
3) Ax/y: Ax = Addr(x), Ay = Addr(y)
, H = VIH, VID = 11.0V ± 0.5V
IL
CE
Pulse L VID VID L X X H X X X X
WE OE
L H L VID L/H L X L L X MANUFACTURE
L H L VID X L X H L X CODE
L Pulse L VID VID X L X X X X X
L H L VID X H X H L X CODE
or VIL
IH
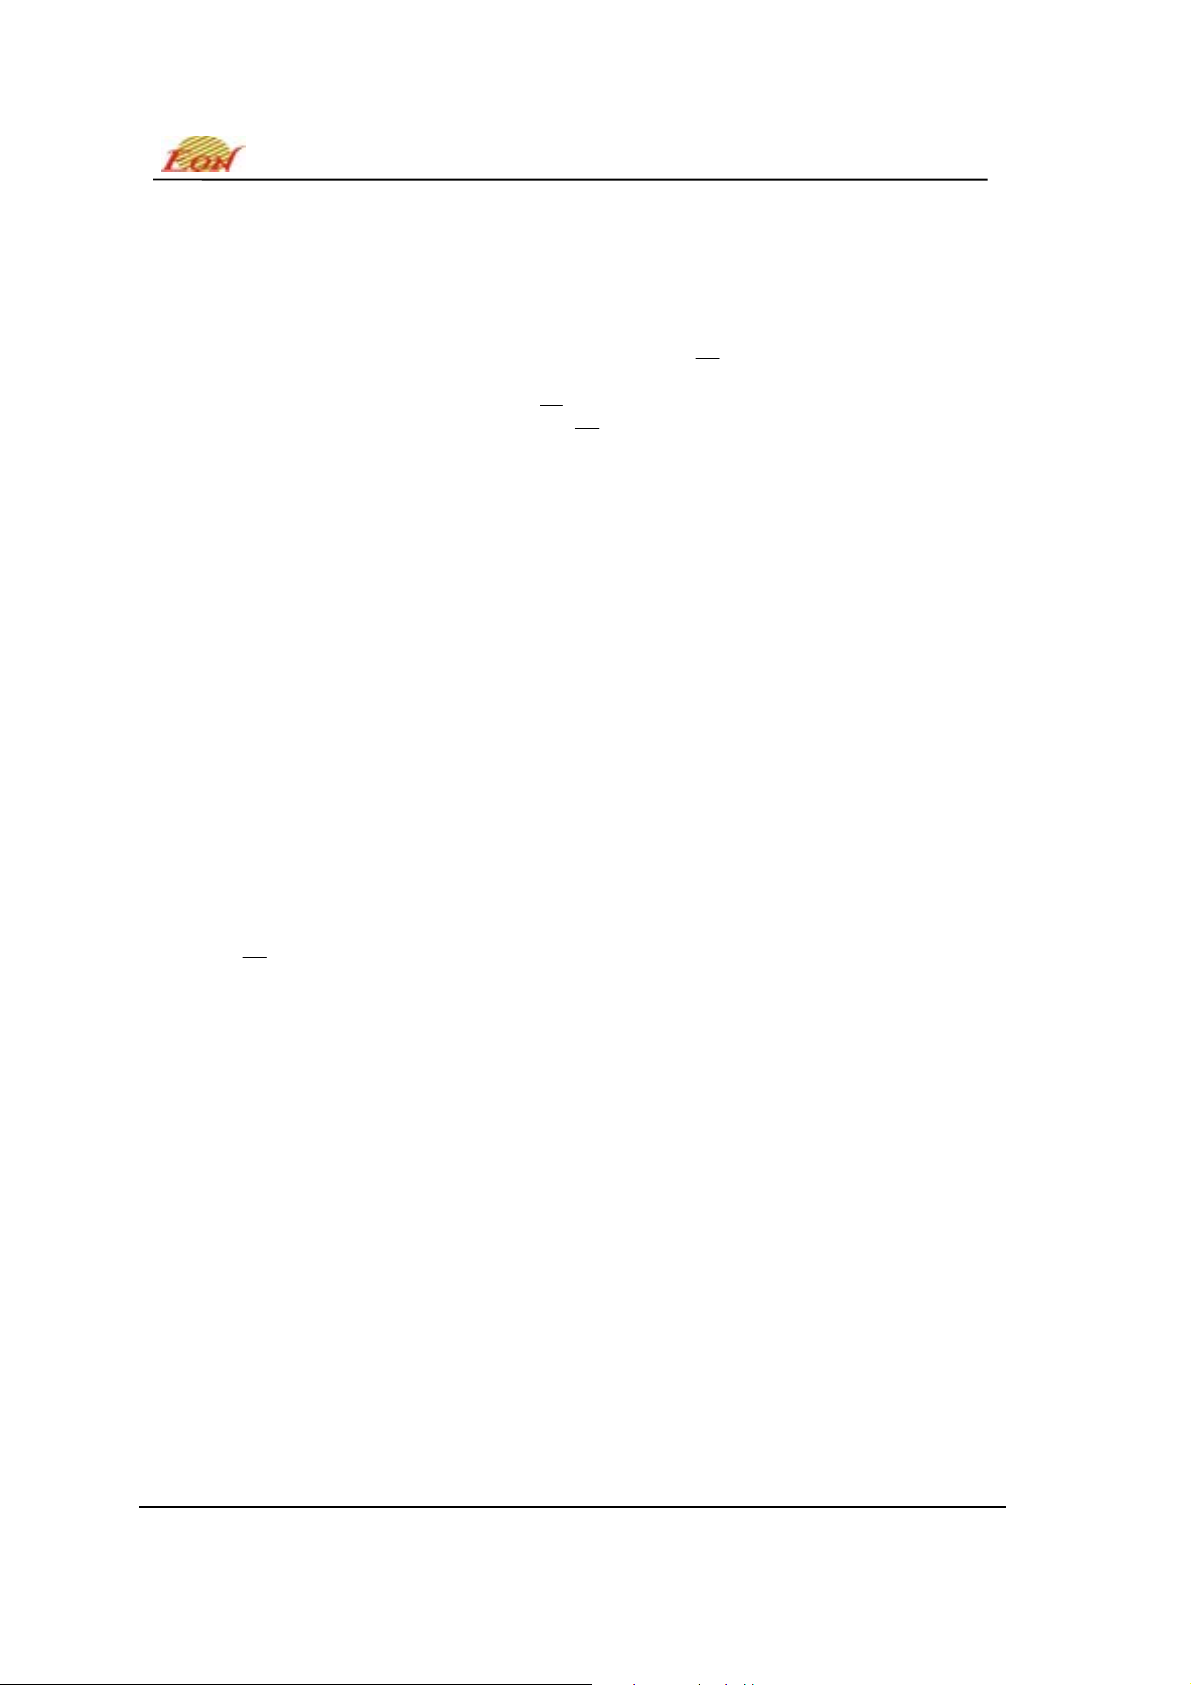
TABLE 4. DEVICE IDENTIFICTION
4M FLASH MANUFACTURER/DEVICE ID TABLE
READ
MANUFACTURER ID
READ
DEVICE ID
NOTES:
1) If a Manufacturing ID is read with A8 = L, the chip will output a configuration code 7Fh. A further
Manufacturing ID must be read with A8 = H.
2) If a Device ID is read with A8 = L, the chip will output a configuration code 7Fh. A further Device ID
must be read with A8 = H.
A8 A6 A1 A0
(1)
H
(2)
H
L L L
L L H
A9 A8 A6 A5 A1 A0 Ax/y DQ(0-7)
ID
DQ(7-0)
HEX
MANUFACTURER ID
1C
DEVICE ID
04
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
5
Rev. B, Issue Date: 2004/04/01
Page 6
EN29F040A
USER MODE DEFINITIONS
Standby Mode
The EN29F040A has a CMOS-compatible standby mode, which reduces the
(typical). It is placed in CMOS-compatible standby when the
also has a TTL-compatible standby mode, which reduces the maximum V
placed in TTL-compatible standby when the
are in a high-impedance state independent of the
pin is at VIH. When in standby modes, the outputs
CE
input.
OE
pin is at VCC ± 0.5. The device
CE
CC
Read Mode
The device is automatically set to reading array data after device power-up. No commands are
required to retrieve data. The device is also ready to read array data after completing an Embedded
Program or Embedded Erase algorithm.
After the device accepts an Erase Suspend command, the device enters the Erase Suspend mode.
The system can read array data using the standard read timings, except that if it reads at an address
within erase-suspended sectors, the device outputs status data. After completing a programming
operation in the Erase Suspend mode, the system may once again read array data with the same
exception. See “Erase Suspend/Erase Resume Commands” for more information on this mode.
The system must issue the reset command to re-enable the device for reading array data if DQ5
goes high, or while in the autoselect mode. See “Reset Command” section.
See also “Requirements for Reading Array Data” in the “Device Bus Operations” section for more
information. The Read Operations table provides the read parameters, and Read Operation Timings
diagram shows the timing diagram.
Output Disable Mode
When the
pin is at a logic high level (VIH), the output from the EN29F040A is disabled. The
OE
output pins are placed in a high impedance state.
Auto Select Identification Mode
The autoselect mode provides manufacturer and device identification, and sector protection
verification, through identifier codes output on DQ7–DQ0. This mode is primarily intended for
programming equipment to automatically match a device to be programmed with its corresponding
programming algorithm. However, the autoselec t co des ca n also be acc ess ed in- system thr ough the
command register.
When using programming equipment, the autoselect mode requires V
address pin A9. Address pins A6, A1, and A0 must be a s shown in Autoselect Codes (High Voltage
Method) table. In addition, when verifying sector protection, the sector address must appear on the
appropriate highest order address bits. Refer to the corresponding Sector Address Tables. The
Command Definitions table shows the remaining address bits that are don’t care. When all
necessary bits have been set as required, the programming equipment may then read the
corresponding identifier code on DQ7–DQ0.
To access the autoselect codes in-system; the host system can issue the autoselect command via
the command register, as s hown in the Command Definitions table. This me thod does not require
V
ID. See “Command Definitions” for details on using the autoselect mode.
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
6
Rev. B, Issue Date: 2004/04/01
ID (10.5 V to 11.5 V) on
current to < 1µA
current to < 1mA. It is
Page 7
EN29F040A
Reset Command
Writing the reset command to the device resets the device to reading array data. Address bits are
don’t care for this command.
The reset command may be written between the sequence cycles in an erase command sequence
before erasing begins. This resets the device to reading array data. Once erasure begins, however,
the device ignores reset commands until the operation is complete. The reset command may be
written between the sequence cycles in a program command sequence before programming begins.
This resets the device to reading array data (also applies to programming in Erase Suspend mode).
Once programming begins, however, the device ignores reset commands until the operation is
complete.
The reset command may be written between the sequence cycles in an autoselect command
sequence. Once in the autoselect mode, the reset command must be written to return to reading
array data (also applies to autoselect during Erase Suspend).
If DQ5 goes high during a program or erase operation, writing the reset command returns the device
to reading array data (also applies during Erase Suspend).
Write Mode
Programming is a four-bus-cycle operation. The program command sequence is initiated by writing
two unlock write cycles, followed by the program set-up command. The program address and data
are written next, which in turn initiate the Embedded Program algorithm. The system is not required
to provide further controls or timings. The device automatically provides internally generated
program pulses and verifies the programmed cell margin. Table 5 (Command Definitions) shows the
address and data requirements for the byte program command sequence.
When the Embedded Program algorithm is complete, the device then returns to reading array data
and addresses are no longer latched. The system can determine the status of the program operation
by using DQ7 or DQ6. See “Write Operation Status” for information on these status bits.
Any commands written to the device during the Embedded Program Algorithm are ignored.
Programming is allowed in any sequence and across sector boundaries. A bit cannot be
programmed from a “0” back to a “1”. Attempting to do so may halt the operation and set DQ5 to
“1”, or cause the Data# Polling algorithm to indicate the operation was successful. However, a
succeeding read will show that the data is still “0”. Only erase operations can convert a “0” to a “1”.
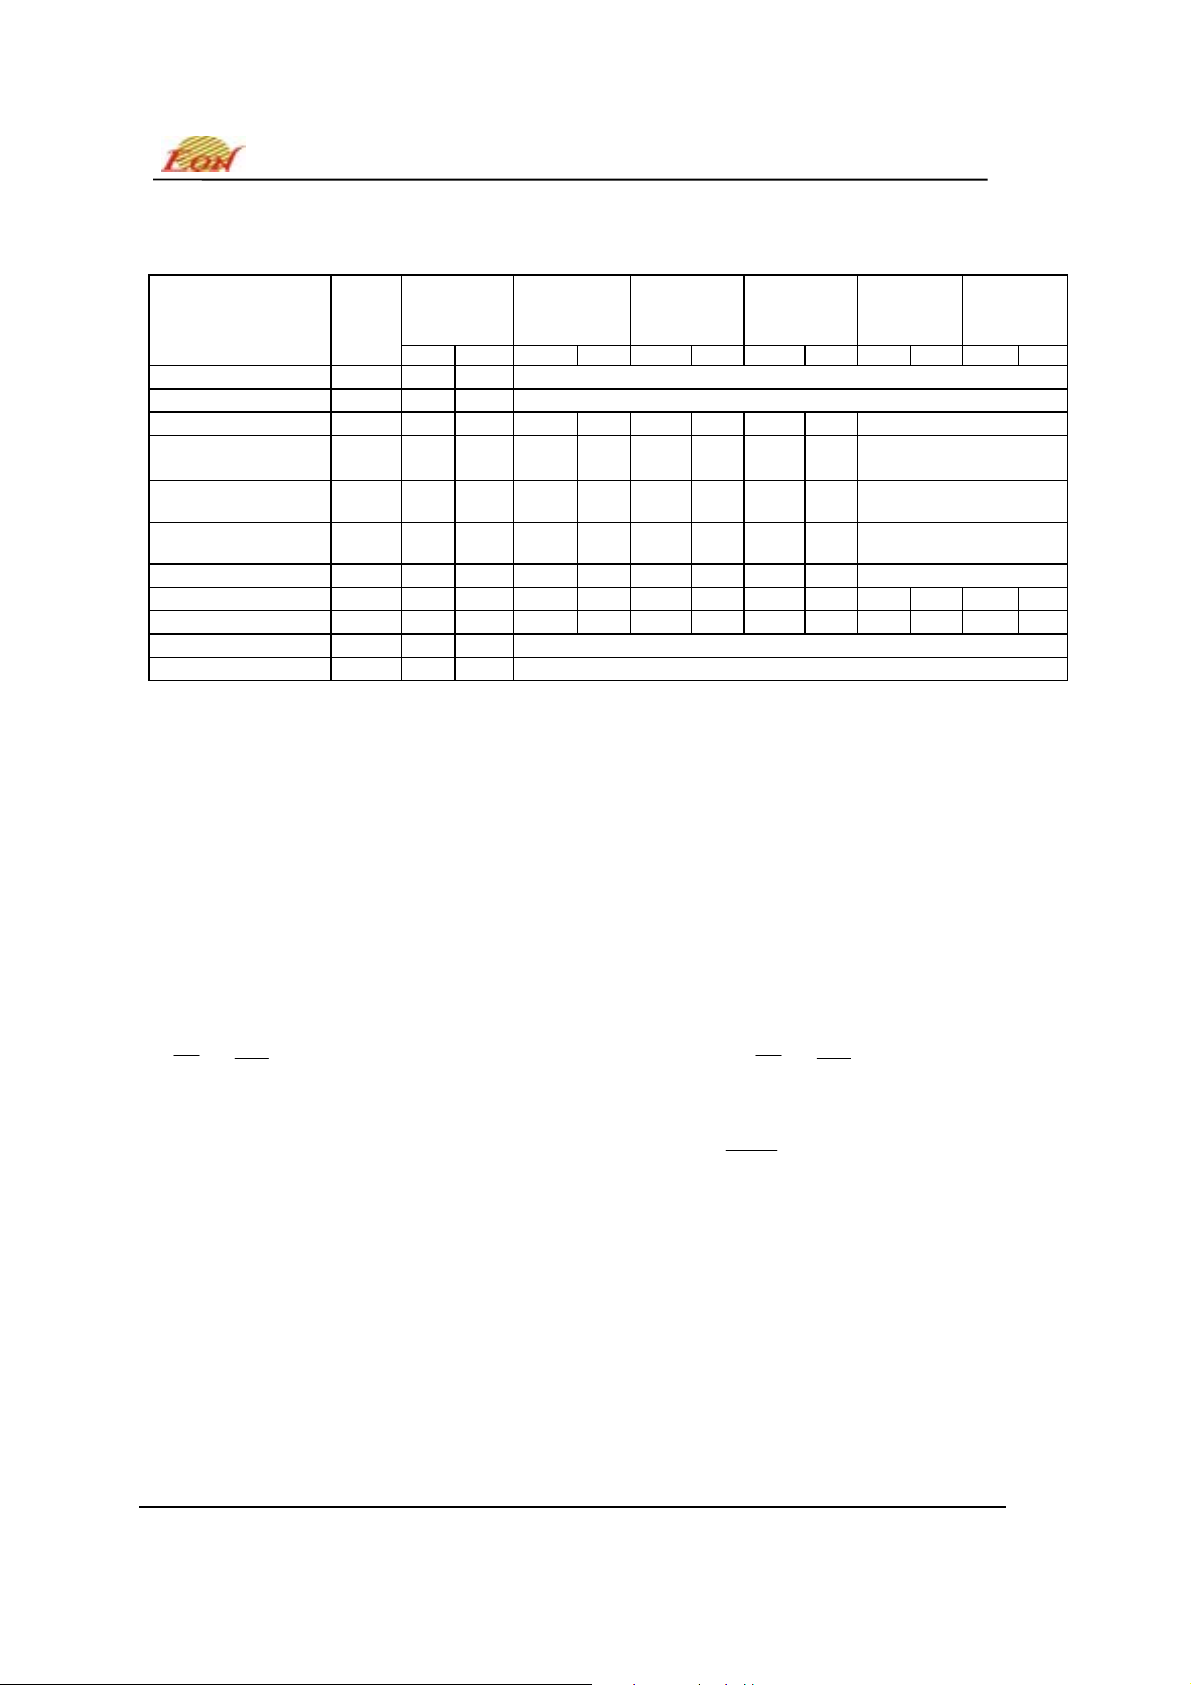
COMMAND DEFINITIONS
The operations of the EN29F040A are selected by one or more commands written into the
command register to perform Read/Reset Memory, Read ID, Read Sector Protection, Program,
Sector Erase, Chip Erase, Erase Suspend a nd Erase Resume. Commands a re made up of data
sequences written at specific addresses via the command register. The sequences for the
specified operation are defined in the Command Table (Table 5). Incorrect addresses, inc orrect
data values or improper sequences will reset the device to the read mode.
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
7
Rev. B, Issue Date: 2004/04/01
Page 8
A
EN29F040A
Table 5. EN29F040A Command Definitions
Command
Sequence
Read/Reset
Read/Reset
AutoSelect
Manufacturer ID
AutoSelect Device ID
AutoSelect Sector
Protect Verify
Byte Program
Chip Erase
Sector Erase
Sector Erase Suspend
Sector Erase Resume
Read
Reset
Write
Cycles
Req’d
1 RA RD
1 XXXh F0h
4 555h AAh 2AAh 55h 555h F0h RA RD
4 555h AAh 2AAh 55h 555h 90h
4 555h AAh 2AAh 55h 555h 90h
4 555h AAh 2AAh 55h 555h 90h
4 555h AAh 2AAh 55h 555h A0h PA PD
6 555h AAh 2AAh 55h 555h 80h 555h AAh 2AAh 55h 555h 10h
6 555h AAh 2AAh 55h 555h 80h 555h AAh 2AAh 55h SA 30h
1 xxxh B0h
1 xxxh 30h
st
1
Write Cycle
Addr Data Addr Data Addr Data Addr Data Addr Data Addr Data
nd
2
Write Cycle
rd
3
Write Cycle
th
4
Write Cycle
000h/
001h/
100h
101h
BA &
02h
7Fh/
1Ch
7Fh/
04h
00h/
01h
th
5
Write Cycle
Notes:
RA = Read Address: address of the memory location to be read. This one is a read cycle.
RD = Read Data: data read from location RA during Read operation.
This one is a read cycle.
PA = Program Address: address of the memory location to be programmed
PD = Program Data: data to be programmed at location PA
SA = Sector Address: address of the Sector to be erased. Address bits A18-A16 uniquely select any Sector.
The data is 00h for an unprotected sector and 01h for a protected sector.
Byte Programming Command
Programming the EN29F040A is performed on a byte- by-byte basi s usin g a four bu s-cyc le oper ation
(two unlock write cycles followed by the Program Setup command and Progr am Data Write cycle).
When the program command is executed, no ad ditional CPU controls or timings are nece ssary. An
internal timer terminates the program operation automatically. Address is latched on the falling edge
of
or WE, whichever is last; data is latched on the rising edge of CE or WE, whichever is first.
CE
The program operation is completed when EN29F040A returns the equivalent data to the
programmed location.
Programming status may be checked by sampling data on DQ7 (
polling) or on DQ6 (toggle
DAT
bit). Changing data from 0 to 1 requires an erase operation. When programming time limit is
exceeded, DQ5 will produce a logical “1” and a Reset command can return the device to Read
mode.
Chip Erase Command
Chip erase is a six-bus-cycle operation. The chip erase command sequence is initiated by writing two
unlock cycles, followed by a set-up command. Two additional unlock write cycles are then followed by the
chip erase command, which in turn invokes the Embedded Erase algorithm. The device does
the system to preprogram prior to erase. The Embedded Erase algorithm automatically preprograms and
verifies the entire memory for an all zero data pattern prior to electrical erase. The system is not required
to provide any controls or timings during these operations. The Command Definitions table shows the
address and data requirements for the chip erase command sequence.
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
8
Rev. B, Issue Date: 2004/04/01
not require
6
Write Cycle
th
Page 9
EN29F040A
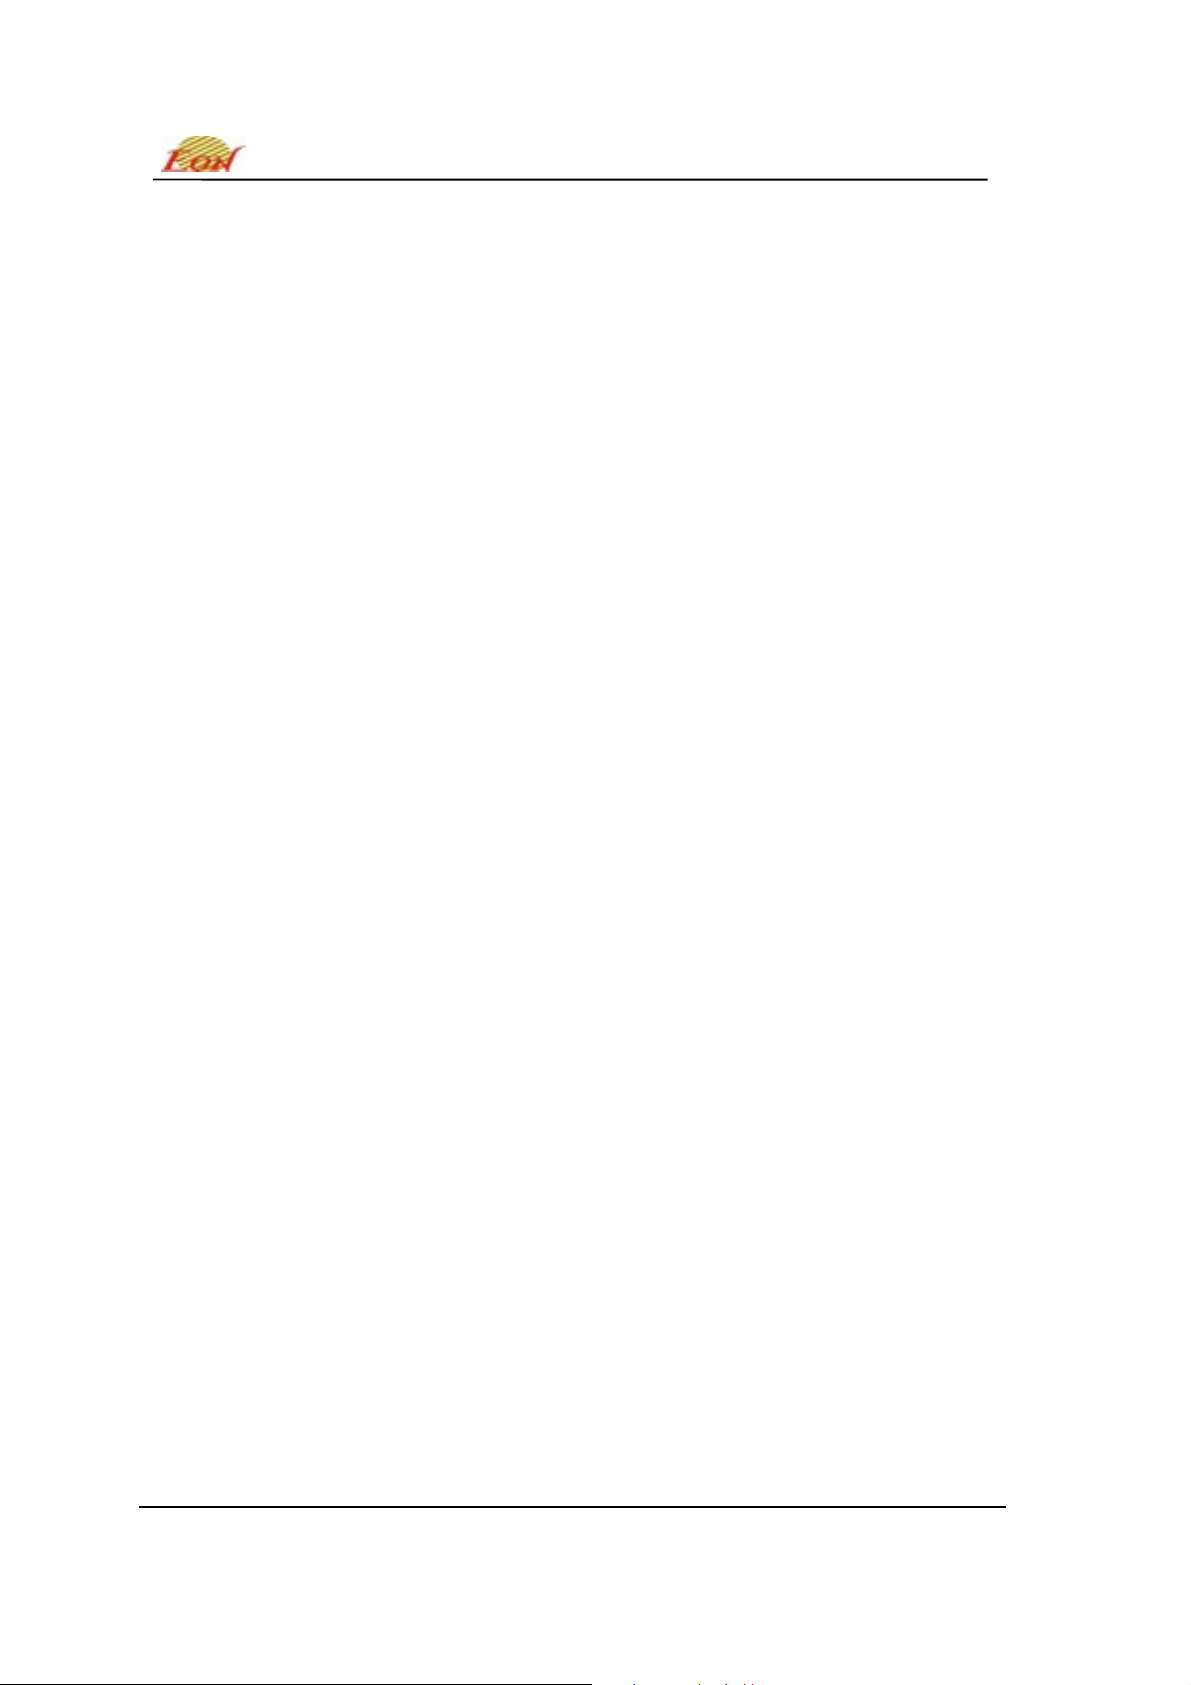
Any commands written to the chip during the Embedded Erase algorithm are ignored.
The system can determine the status of the erase operation by using DQ7, DQ6, or DQ2. See “Write
Operation Status” for information on these status bits. When the Embedded Erase algorithm is complete,
the device returns to reading array data and addresses are no longer latched.
Flowchart 4 illustrates the algorithm for the erase operation. See the Erase/Program Operations tables in
“AC Characteristics” for parameters, and Chip/Sector Erase Operation Timings for timing waveforms.
Sector Erase Command
Sector erase is a six bus cycle operation. The sector erase command sequence is initiated by writing two
un-lock cycles, followed by a set-up command. Two additional unlock write cycles are then followed by the
address of the sector to be erased, and the sector erase command. The Command Definitions table
shows the address and data requirements for the sector erase command sequence.
The device does
algorithm automatically programs and verifies the sector for an all zero data pattern prior to electrical
erase. The system is not required to provide any controls or timings during these operations.
not require the system to preprogram the memory prior to erase. The Embedded Erase
This device does not support multiple sector erase commands. Sector Erase operation will
commence immediately after the first 30h command is written. The first sector erase operation must
finish before another sector erase command can be given.
Once the sector erase operation has begun, only the Erase Suspend command is valid. All other
commands are ignored.
When the Embedded Erase algorithm is complete, the device returns to reading array data and addresses
are no longer latched. The system can determine the status of the erase operation by using DQ7, DQ6, or
DQ2. Refer to “Write Operation Status” for information on these status bits. Flowchart 4 illustrates the
algorithm for the erase operation. Refer to the Erase/Program Operations tables in the “AC
Characteristics” section for parameters, and to the Sector Erase Operations Timing diagram for timing
waveforms.
Erase Suspend / Resume Command
The Erase Suspend command allows the system to interrupt a sector erase operation and then read data
from, or program data to, any sector not selected for erasur e. This command is valid only during the
sector erase operation. The Erase Suspend command is ignored if written during the chip erase operation
or Embedded Program algorithm. Addresses are “don’t-cares” when writing the Erase Suspend command.
When the Erase Suspend command is written during a sector erase operation, the device requires a
maximum of 20 µs to suspend the erase operation.
After the erase operation has been suspended, the system can read array data from or program data to
any sector not selected for erasure. (The device “erase suspends” all sectors selected for erasure.)
Normal read and write timings and command definitions apply. Reading at any address within erasesuspended sectors produces status data on DQ7–DQ0. The system can use DQ7, or DQ6 and DQ2
together, to determine if a sector is actively erasing or is erase-suspended. See “Write Operation Status”
for information on these status bits.
After an erase-suspended program operation is complete, the system can once again read array data
within non-suspended sectors. The system can determine the status of the program operation using the
DQ7 or DQ6 status bits, just as in the standard program operation. See “Write Operation Status” for more
information.
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
9
Rev. B, Issue Date: 2004/04/01
Page 10
EN29F040A
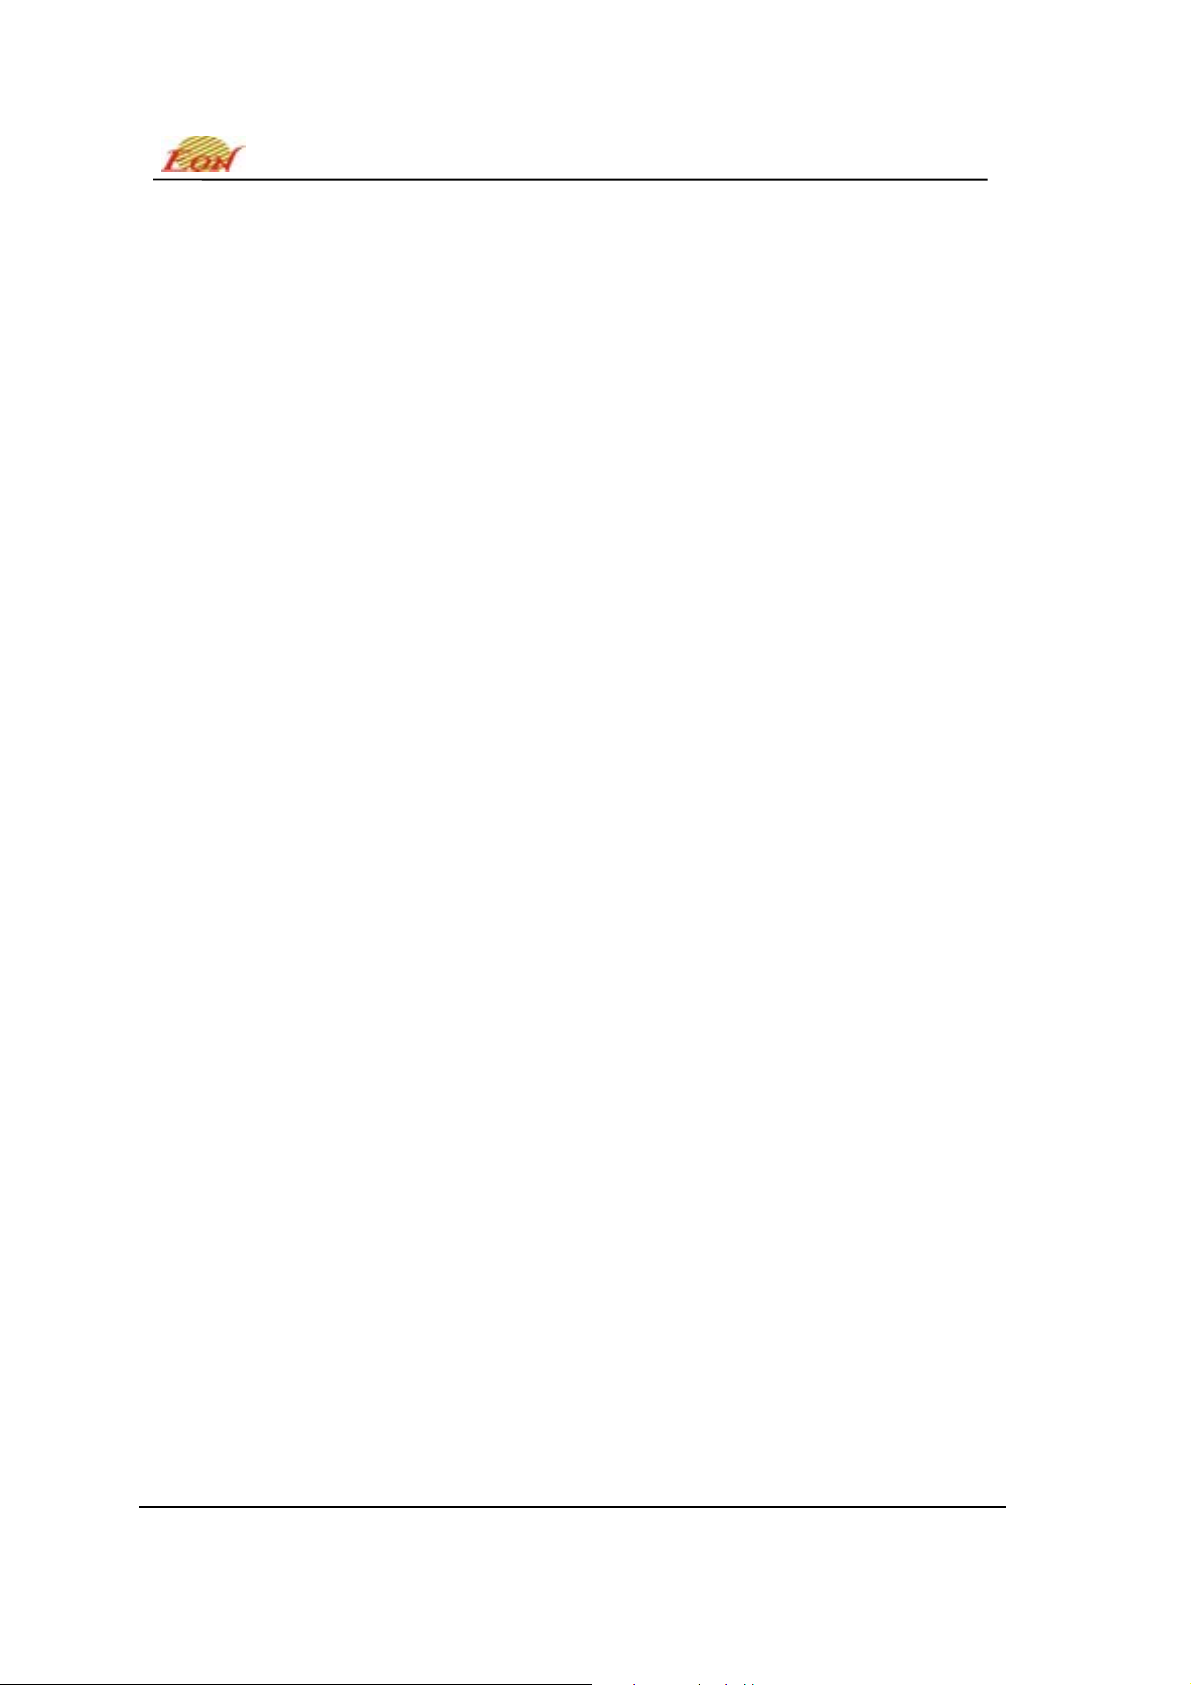
The system must write the Erase Resume command (address bits are “don’t care”) to exit the
erase suspend mode and continue the sector erase operation. Further writes of the Resume command
are ignored. Another Erase Suspend command can be written after the device has resumed erasing.
Sector Protection/Unprotection
The hardware sector protection feature disables both program and erase operations in any sector. The
hardware sector unprotection feature re-enables both program and erase operations in previously
protected sectors.
Sector protection/unprotection must be implemented using programming equipment. The procedure requires a high voltage (V
an additional supplement on this feature.
ID) on address pin A9 and the control pins. Contact Eon Silicon Solution, Inc. for
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
10
Rev. B, Issue Date: 2004/04/01
Page 11
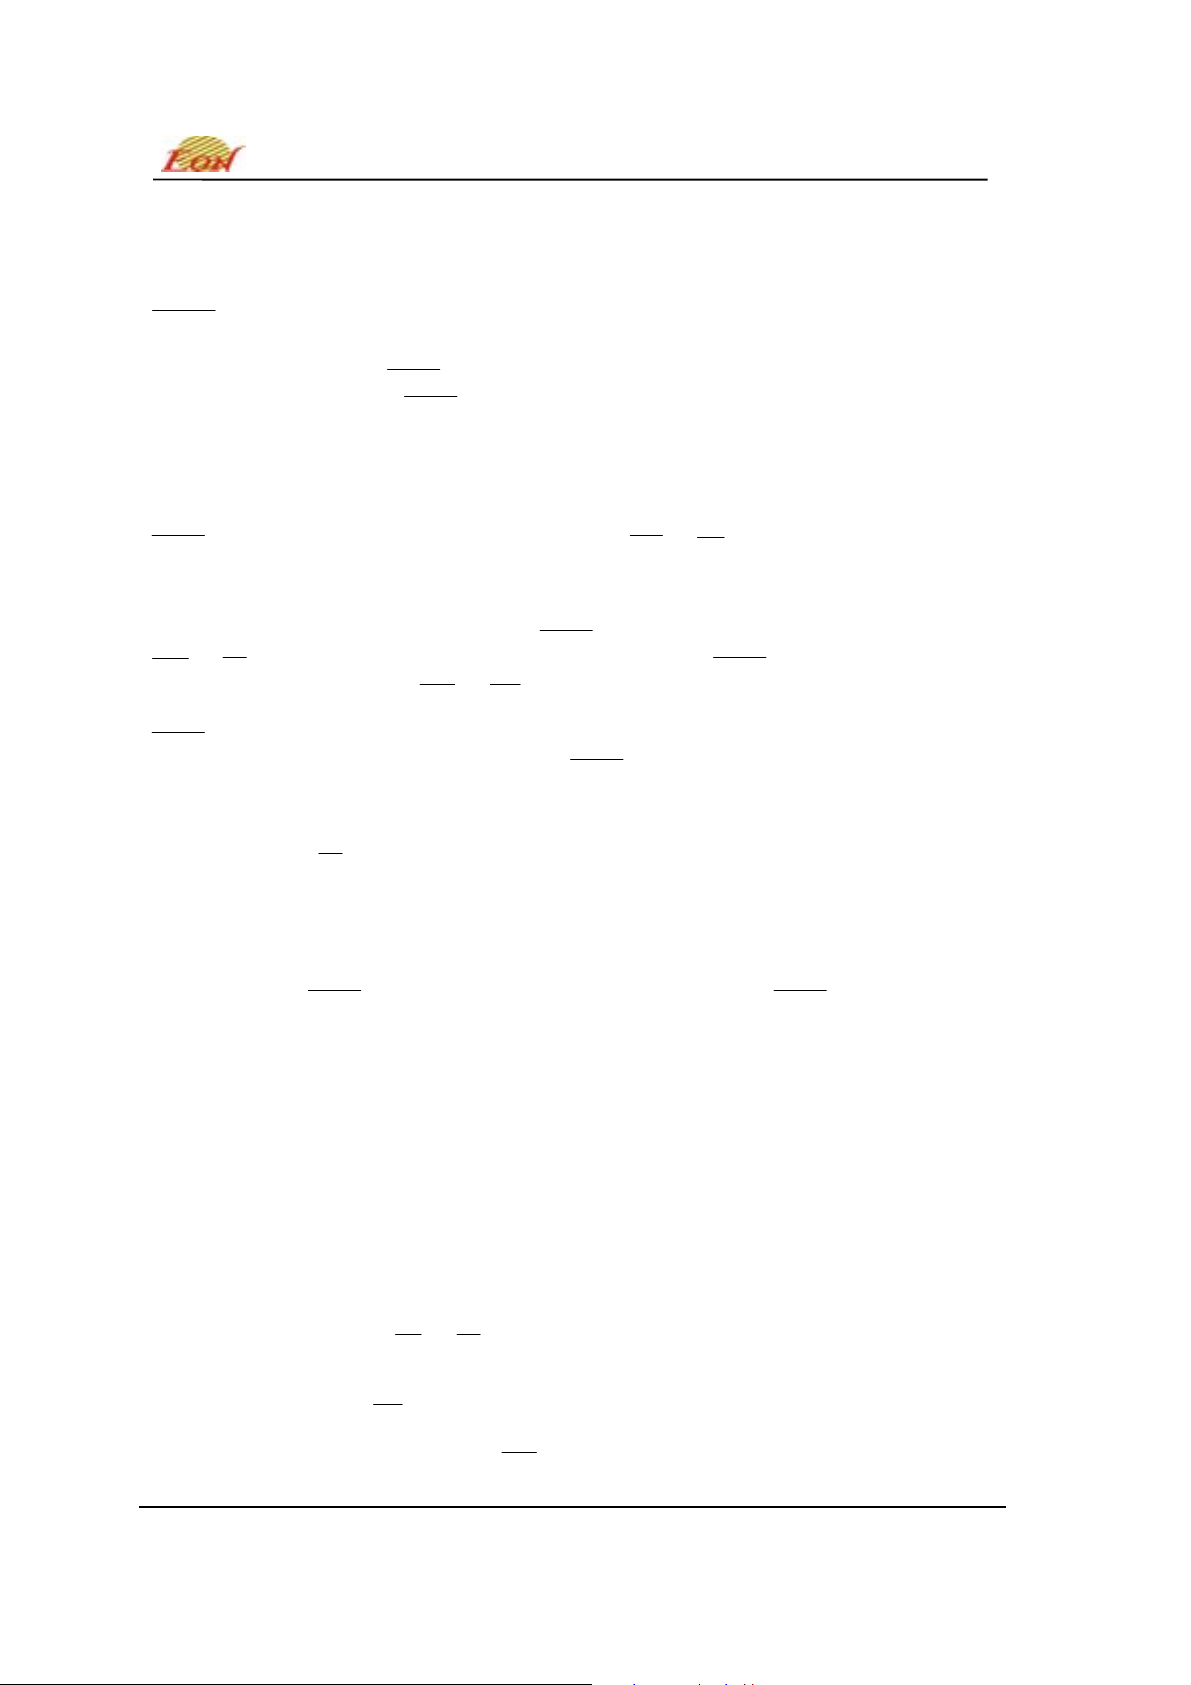
A
EN29F040A
WRITE OPERATION STATUS
DQ7
DAT
The EN29F040A provides
embedded operations. The
Erase, Chip Erase, and Erase Suspend. (See Table 6)
When the Byte Programming is in progress, an attempt to read the device will produce the
complement of the data last written to DQ7. Upon the completion of the Byte Programming, an
attempt to read the device will produce the true data last written to DQ7. For the Byte Programming,
DATA
When the embedded Erase is in progress, an attempt to read the device will produce a “0” at the
DQ7 output. Upon the completion of the embedded Erase, the device will produce the “1” at the DQ7
output during the read. For Chip Erase, the
WE
rising edge of the sector erase
DATA
erased and not a protected sector. Otherwise,
address used is in a protected sector.
Just prior to the completion of the e mbedded operations, DQ7 may change asynchronous ly when
the output enable (
one instant of time and valid data at the next instant of time. Depending on when the system
samples the DQ7 output, it may read the status of valid data. Even if the devic e has completed the
embedded operations and DQ7 has a valid data, the data output on DQ0-DQ6 may be still invalid.
The valid data on DQ0-DQ7 will be read on the subsequent read attempts.
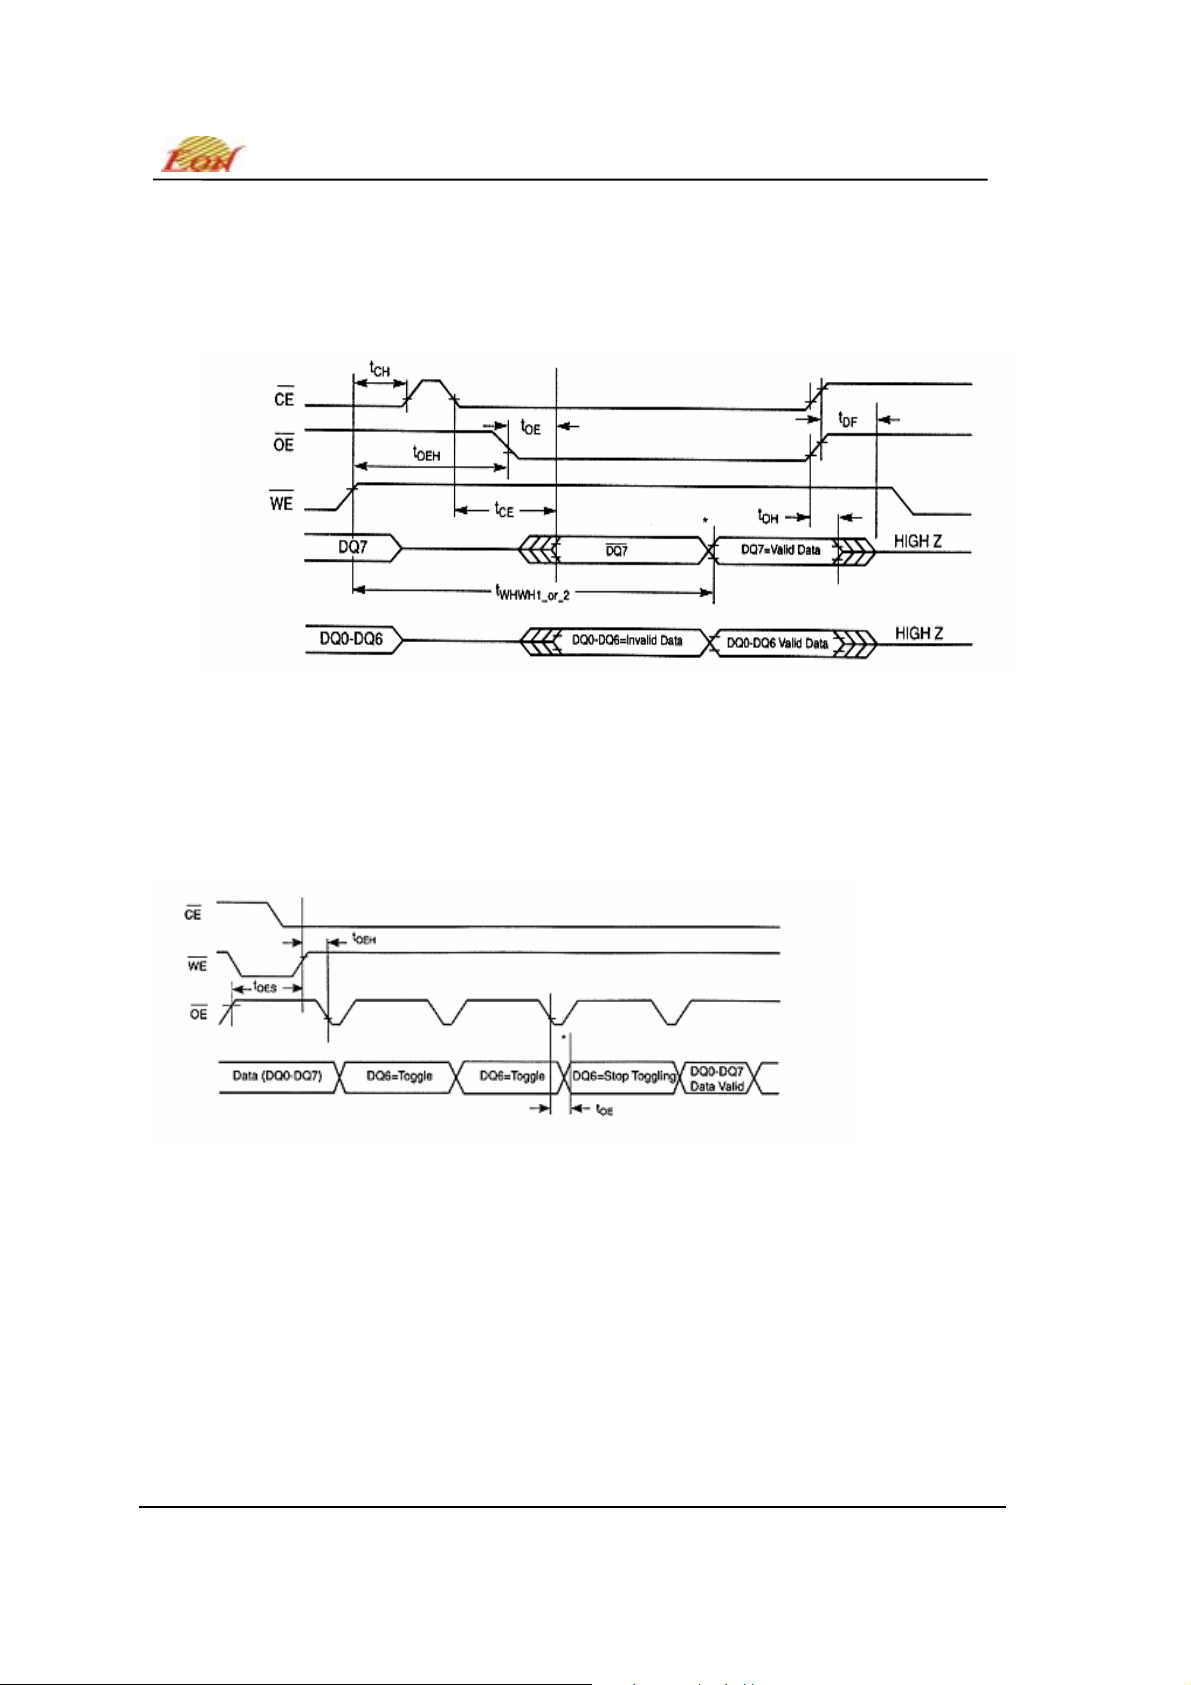
The flowchart for
diagram is shown in Figure 8.
DQ6
Toggle Bit I
The EN29F040A provides a “Toggle Bit” o n DQ6 to indicate to the host system the status of the
embedded programming and erase operations. (See Table 6)
During an embedded Program or Erase op eration , succ es sive a ttempts to rea d da ta fr om the d evice
at any address (by toggling
the embedded Program or Erase operation is complete, DQ6 will stop toggling and valid data will be
read on the next successive atte mpts. During Byte Programming, the Toggle Bit is valid after the
rising edge of the fourth
valid after the rising edge of the sixth-cycle sequen ce. For Sector Eras e, the Toggle Bit is valid after
the last rising edge of the Sector Erase
erase time-out window.
Polling
Polling on DQ7 to indicate to the host system the status of the
DATA
Polling feature is active during the Byte Programming, Sector
DATA
polling is valid after the rising edge of the fourth
polling is valid after the rising edge of the sixth
DATA
or CE pulse in the six-cycle sequence. For Sector Erase,
or
WE
Polling must be performed at any address within a sector that is being programmed or
CE
pulse.
DATA
) is low. This means that the device is driving status information o n DQ7 at
OE
Polling (DQ7) is shown on Flowchart 5. The
DATA
or CE) will result in DQ6 toggling between “zero” and “one ”. Once
OE
pulse in the four-cycle sequence. For Chip Erase, the Toggle Bit is
WE
pulse. The Toggle Bit is also active during the sector
WE
or CEpulse in the four-cycle sequence.
WE
polling is valid after the last
DATA
polling may give an inaccurate result if the
Polling (DQ7) timing
DATA
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
11
Rev. B, Issue Date: 2004/04/01
Page 12
EN29F040A
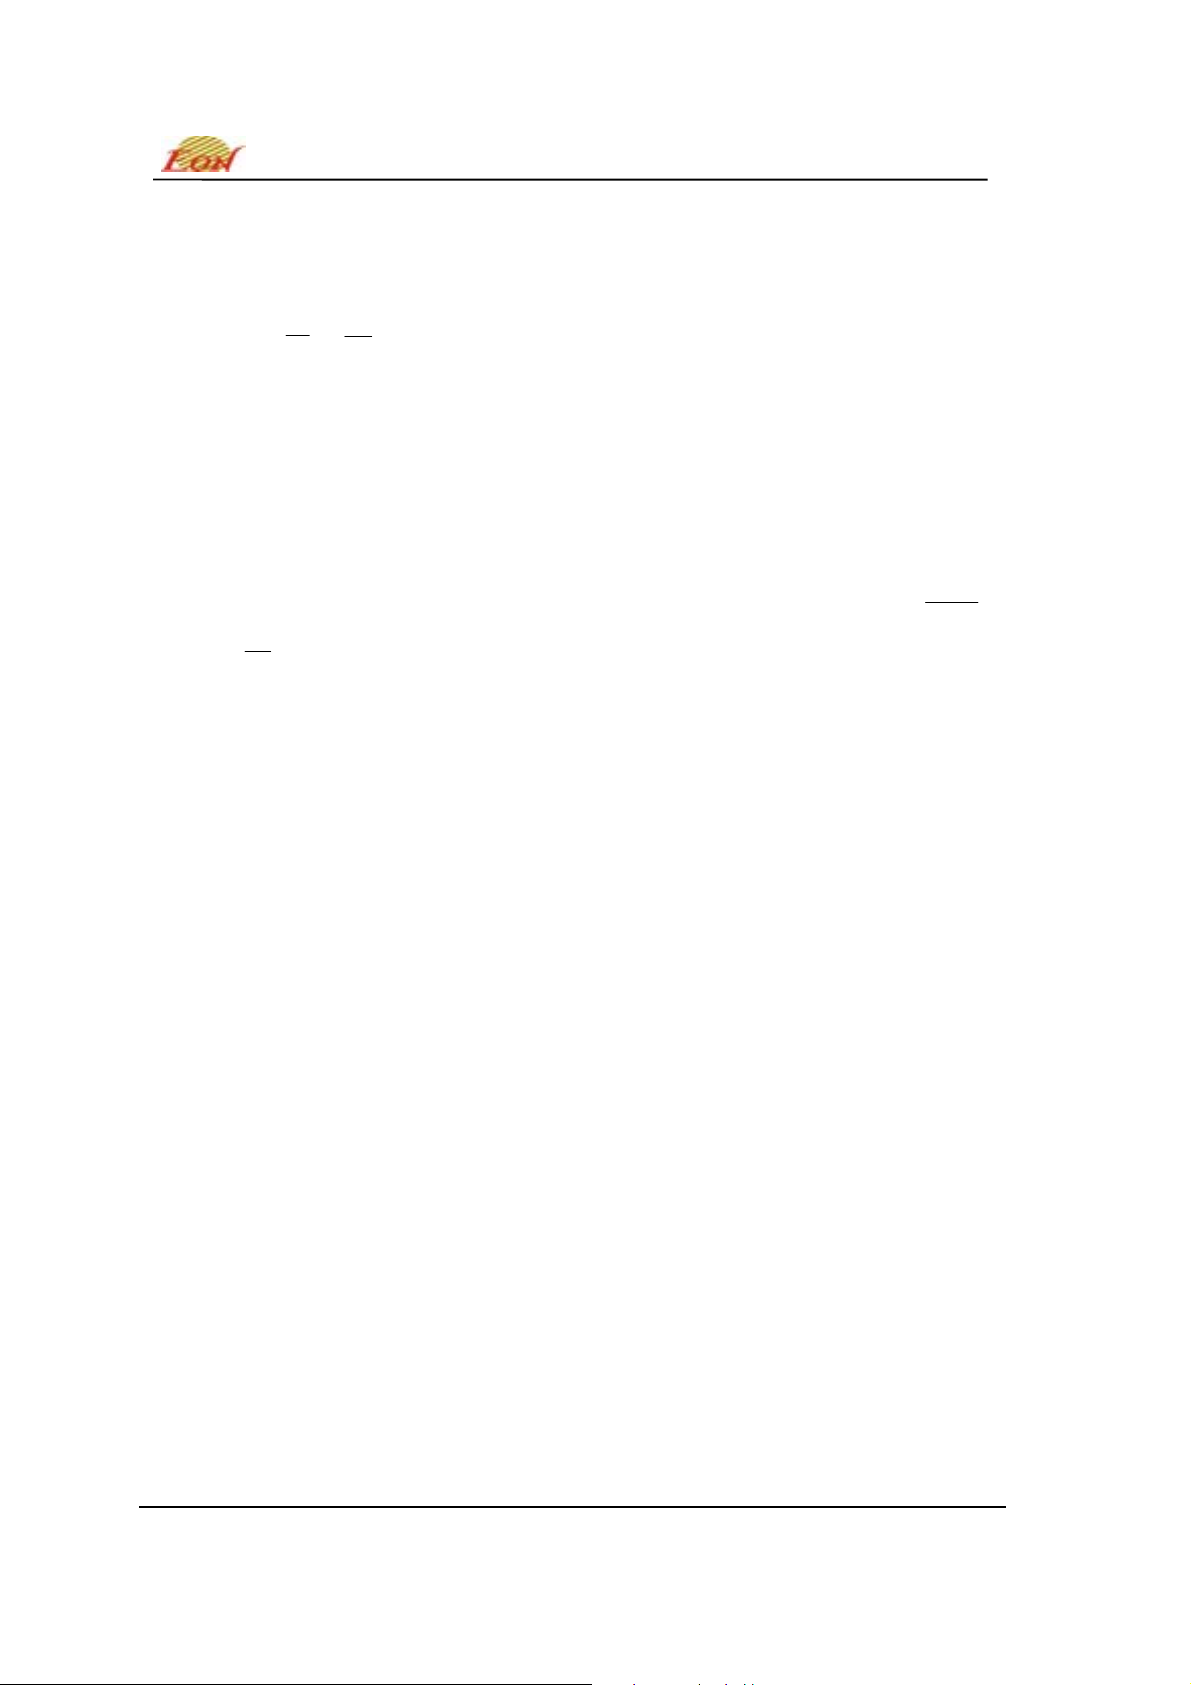
In Byte Programming, if the sector being written to is protected, DQ6 will toggles for about 2 µs, then
stop toggling without the data in the sec tor having changed. In Sector Erase or Chip Erase, if all
selected sectors are protected, DQ6 will toggle for about 100 µs. The chip will then return to the read
mode without changing data in all protected sectors.
Toggling either
or OE will cause DQ6 to toggle.
CE
The flowchart for the Toggle Bit (DQ6) is shown in Flowc hart 6. The Toggle Bit timing diagram is
shown in Figure 9
.
DQ5 Exceeded Timing Limits
DQ5 indicates whether the program or erase time has exceeded a specified internal pulse count limit.
Under these conditions DQ5 produces a “1.” (
time to make sure that the DQ5 is not a “1” due to the device having returned to read mode.)
a failure condition that indicates the program or erase cycle was not successfully completed.
Polling (DQ7), Toggle Bit (DQ6) and Erase Toggle Bit (DQ2) still function under this condition.
Setting the
The DQ5 failure condition may appear if the system tries to program a “1” to a location that is previously
programmed to “0.” Only an erase operation can change a “0” back to a “1.” Under this condition, the
device halts the operation, and when the operation has exceeded the timing limits, DQ5 produces a “1.”
Under both these conditions, the system must issue the reset command to return the device to reading
array data.
to VIH will partially power down the device under those conditions.
CE
The Toggle Bit (DQ6) should also be checked at this
.
DATA
DQ2 Erase Toggle Bit II
The “Toggle Bit” on DQ2, when used with DQ6, indicates whether a particular sector is actively erasing
(that is, the Embedded Erase algorithm is in progress), or whether that sector is erase-suspended. Toggle
Bit II is valid after the rising edge of the final WE# pulse in the command sequence. DQ2 toggles when the
system reads at addresses within those sectors that have been selected for erasure. (The system may
use either OE# or CE# to control the read cycles.) But DQ2 cannot distinguish whether the sector is
actively erasing or is erase-suspended. DQ6, by comparison, indicates whether the device is actively
erasing, or is in Erase Suspend, but cannot distinguish which sectors are selected for erasure. Thus, both
status bits are required for sector and mode information. Refer to Table 6 to compare outputs for DQ2 and
DQ6.
Flowchart 6 shows the toggle bit algorithm, and the section “DQ2: Toggle Bit” explains the algorithm. See
also the “DQ6: Toggle Bit I” subsection. Refer to the Toggle Bit Timings figure for the toggle bit timing
diagram. The DQ2 vs. DQ6 figure shows the differences between DQ2 and DQ6 in graphical form.
Reading Toggle Bits DQ6/DQ2
Refer to Flowchart 6 for the following discussion. Whenever the system initially begins reading toggle bit
status, it must read DQ7–DQ0 at least twice in a row to determine whether a toggle bit is toggling.
Typically, a system would note and store the value of the toggle bit after the first read. After the second
read, the system would compare the new value of the toggle bit with the first. If the toggle bit is not
toggling, the device has completed the program or erase operation. The system can read array data on
DQ7–DQ0 on the following read cycle.
However, if after the initial two read cycles, the system determines that the toggle bit is still toggling, the
system also should note whether the value of DQ5 is high (see the section on DQ5). If it is, the system
should then determine again whether the toggle bit is toggling, since the toggle bit may have stopped
toggling just as DQ5 went high. If the toggle bit is no longer toggling, the device has successfully
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
12
Rev. B, Issue Date: 2004/04/01
This is
Page 13
EN29F040A
completed the program or erase operation. If it is still toggling, the device did not complete the operation
successfully, and the system must write the reset command to return to reading array data.
The remaining scenario is that the system initially determines that the toggle bit is toggling and DQ5 has
not gone high. The system may continue to monitor the toggle bit and DQ5 through successive read
cycles, determining the status as described in the previous paragraph. Alternatively, it may choose to
perform other system tasks. In this case, the system must start at the beginning of the algorithm when it
returns to determine the status of the operation (top of Flowchart 6).
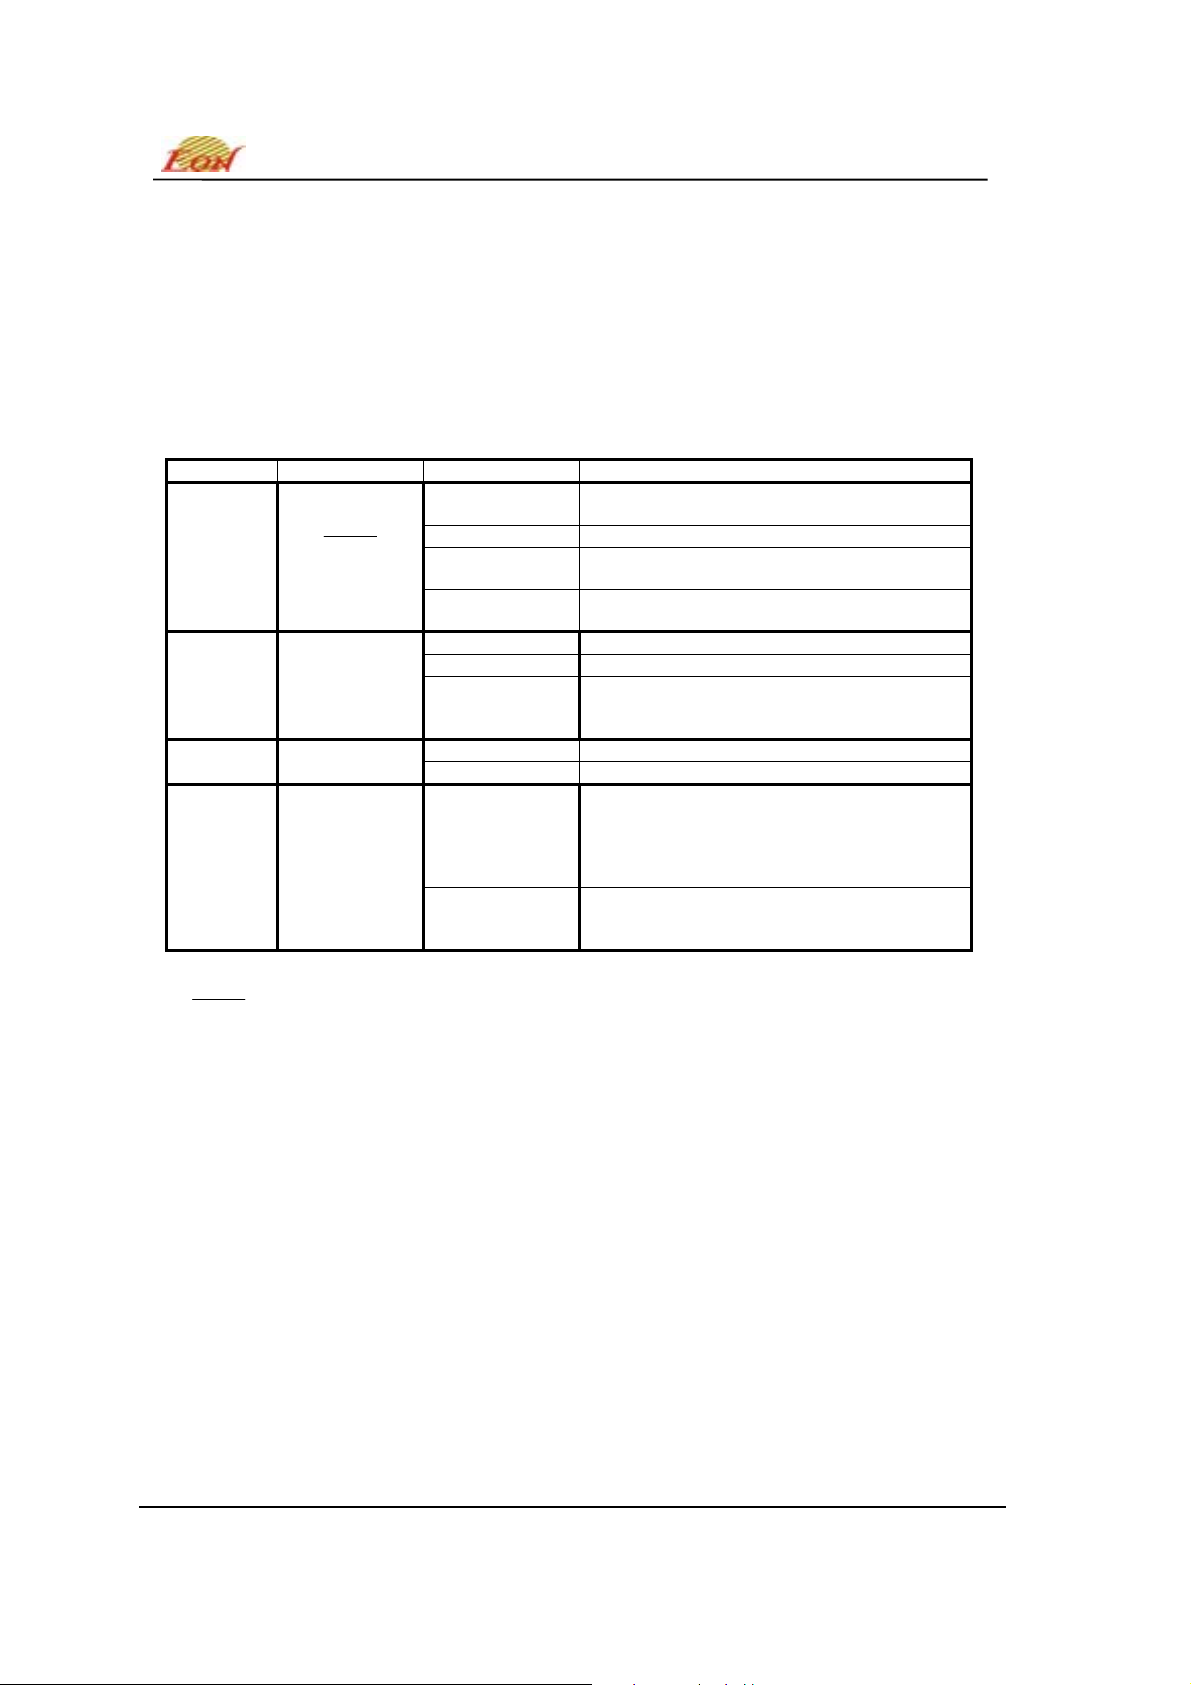
Table 6. Status Register Bits
DQ Name Logic Level Definition
‘1’
7
6
5 ERROR BIT
2
POLLING
TOGGLE
TOGGLE
DATA
BIT
BIT
‘0’ Erase On-Going
DQ7
DQ7
‘-1-0-1-0-1-0-1-’ Erase or Program On-going
DQ6 Read during Erase Suspend
‘-1-1-1-1-1-1-1-‘
‘1’ Program or Erase Erro r
‘0’ Program or Erase O n-going
‘-1-0-1-0-1-0-1-’
DQ2
data of non-erase Sector during Erase Suspend
Chip Erase, Sector Erase or Erase suspend on
(When DQ5=1, Erase Error due to currently
addressed Sector. Program during Erase
Suspend on-going at current address
Notes:
DQ7
for Program or Erase Success.
DQ6 Toggle Bit: remains at constant level when P/E operations are complete or erase suspend is acknowledged.
Successive reads output complementary data on DQ6 while programming or Erase operation are on-going.
DQ5 Error Bit: set to “1” if failure in programming or erase
Polling: indicates the P/E status check during Program or Erase, and on completion before checking bits DQ5
DATA
DQ2 Toggle Bit: indicates the Erase status and allows identification of the erased Sector.
Erase Complete or
erase Sector in Erase suspend
Program Complete or
Program On-Going
Erase Complete
currently addressed Sector.
Erase Suspend read on
non Erase Suspend Sector
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
13
Rev. B, Issue Date: 2004/04/01
Page 14
EN29F040A
DATA PROTECTION
CC
< V
, the command register is disabled and all internal program or
LOK
OE, CE
> V
CC
or WE will neither initiate a write cycle nor change the
LKO.
Power-up Write Inhibit
During power-up, the device autom atically resets to READ mode and locks out write cycles. Even
with
WE
= VIL, WE = VIL and OE = VIH, the device will not accept commands on the rising edge of
CE
.
Low VCC Write Inhibit
During V
power-up or power-down, the EN29F040A locks out write cycles to protect against any
CC
unintentional writes. If V
erase circuits are disabled. Under this condition, the device will reset to the READ mode.
Subsequent writes will be ignored until V
Write “Noise” Pulse Protection
Noise pulses less than 5ns on
command register.
Logical Inhibit
=VIH or WE=VIH, writing is inhibited. To initiate a write cycle, CE and
If
CE
,
“zero”. If
CE
, and OE are all logical zero (not recommended usage), it will be considered a
WE
must be a logical
WE
write.
Sector Protect and Unprotect
The hardware sector protection feature disables both program and erase operations in any sector.
The hardware sector unprotection feature re-enables both program and erase operation in
previously protected sectors.
Sector protection/unprotection mus t be implemen te d usin g pr ogramm ing equ ipment. The proc edure
requires a high voltage (V
Inc. for an additional supplement on this feature.
) on address pin A9 and the control pins. Contact Eon Silicon Solution,
ID
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
14
Rev. B, Issue Date: 2004/04/01
Page 15
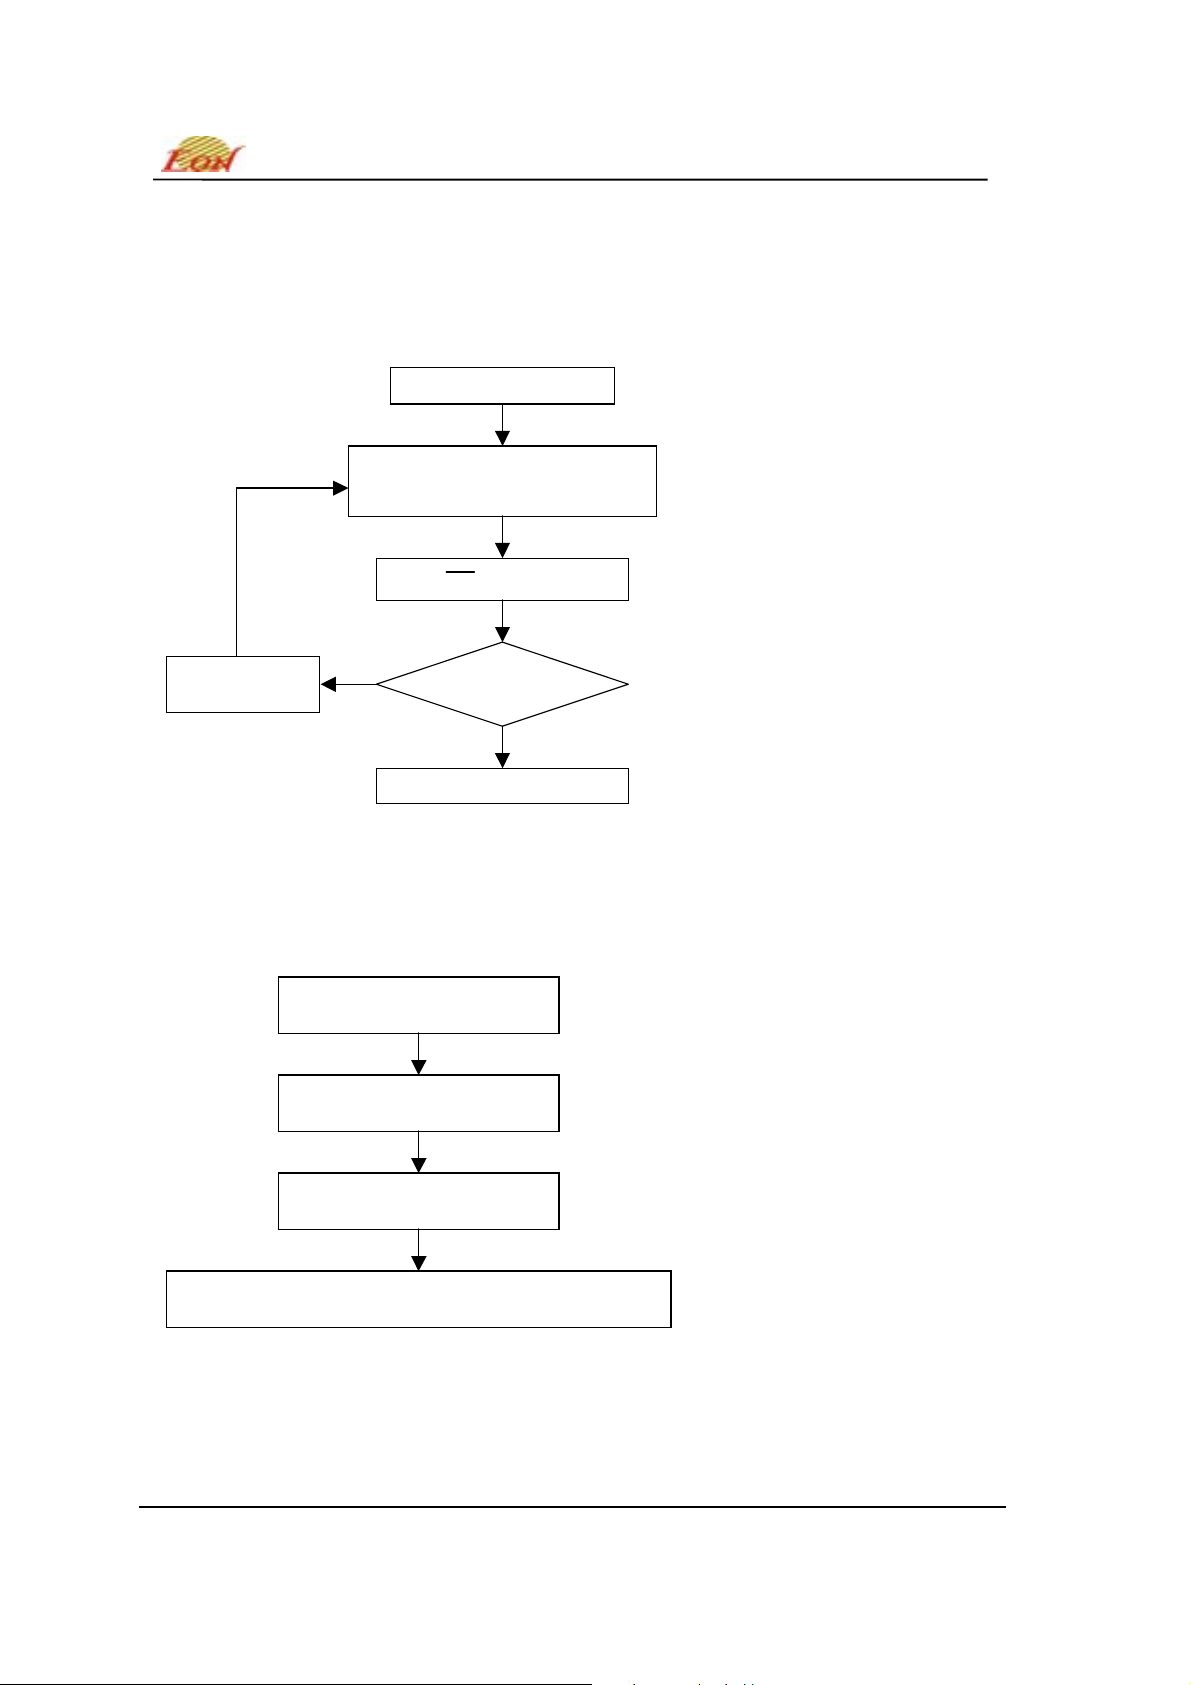
EMBEDDED ALGORITHMS
Flowchart 1. Embedded Program
START
Write Program
Command Sequence
(shown below)
Data Poll Device
EN29F040A
Increment
Address
No
Last
Address?
Yes
Programming Done
Flowchart 2. Embedded Program Command Sequence
See the Command Definitions section for more information.
555H / AAH
2AAH / 55H
555H / A0H
PROGRAM ADDRESS / PROGRAM DATA
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
15
Rev. B, Issue Date: 2004/04/01
Page 16
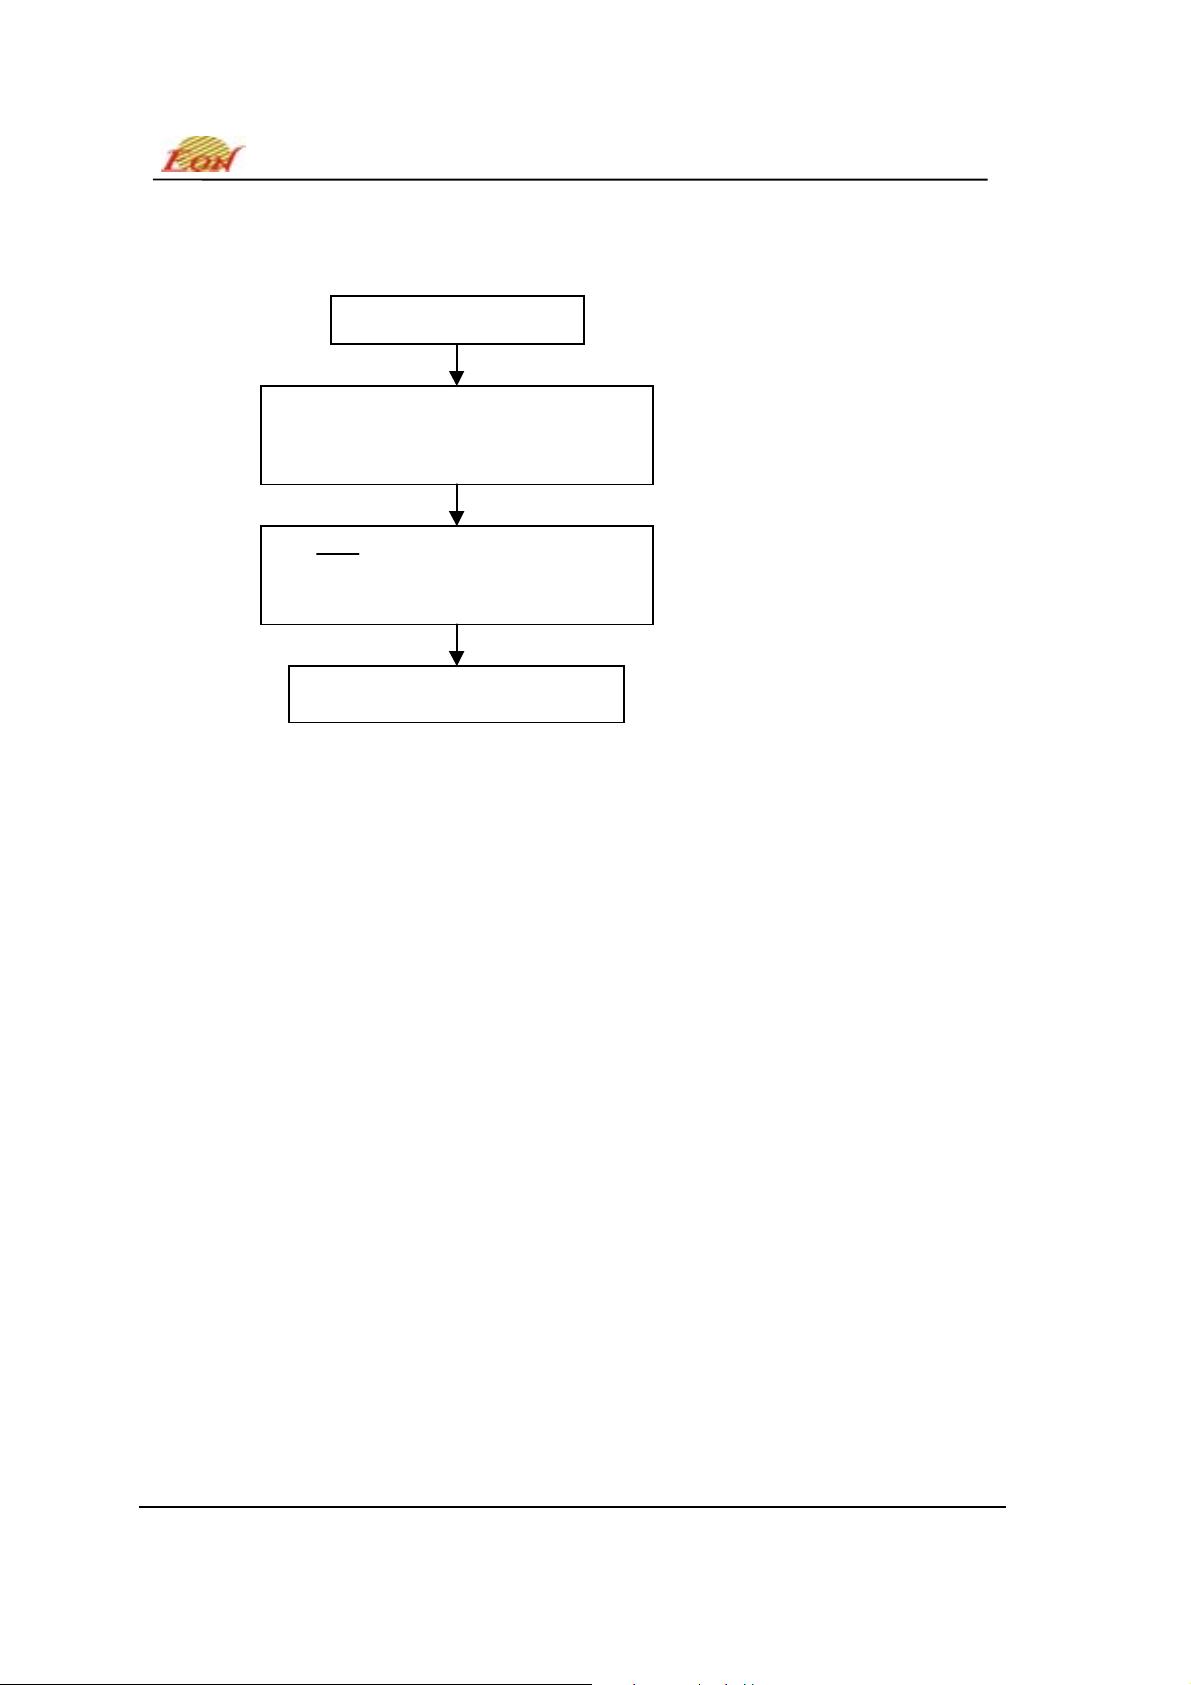
Flowchart 3. Embedded Erase
START
Write Erase
Command Sequence
(shown b elow)
Data Polling Device or Toggle Bit
Successfully Completed
ERASE Done
EN29F040A
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
16
Rev. B, Issue Date: 2004/04/01
Page 17
Flowchart 4. Embedded Erase
See the Command Definitions section for more information.
Chip Erase Sector Erase
555H/AAH
Command Sequence
555H/AAH
EN29F040A
2AAH/55H
555H/80H
555H/AAH
2AAH/55H
555H/10H
2AAH/55H
555H/80H
555H/AAH
2AAH/55H
Sector Address/30H
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
17
Rev. B, Issue Date: 2004/04/01
Page 18
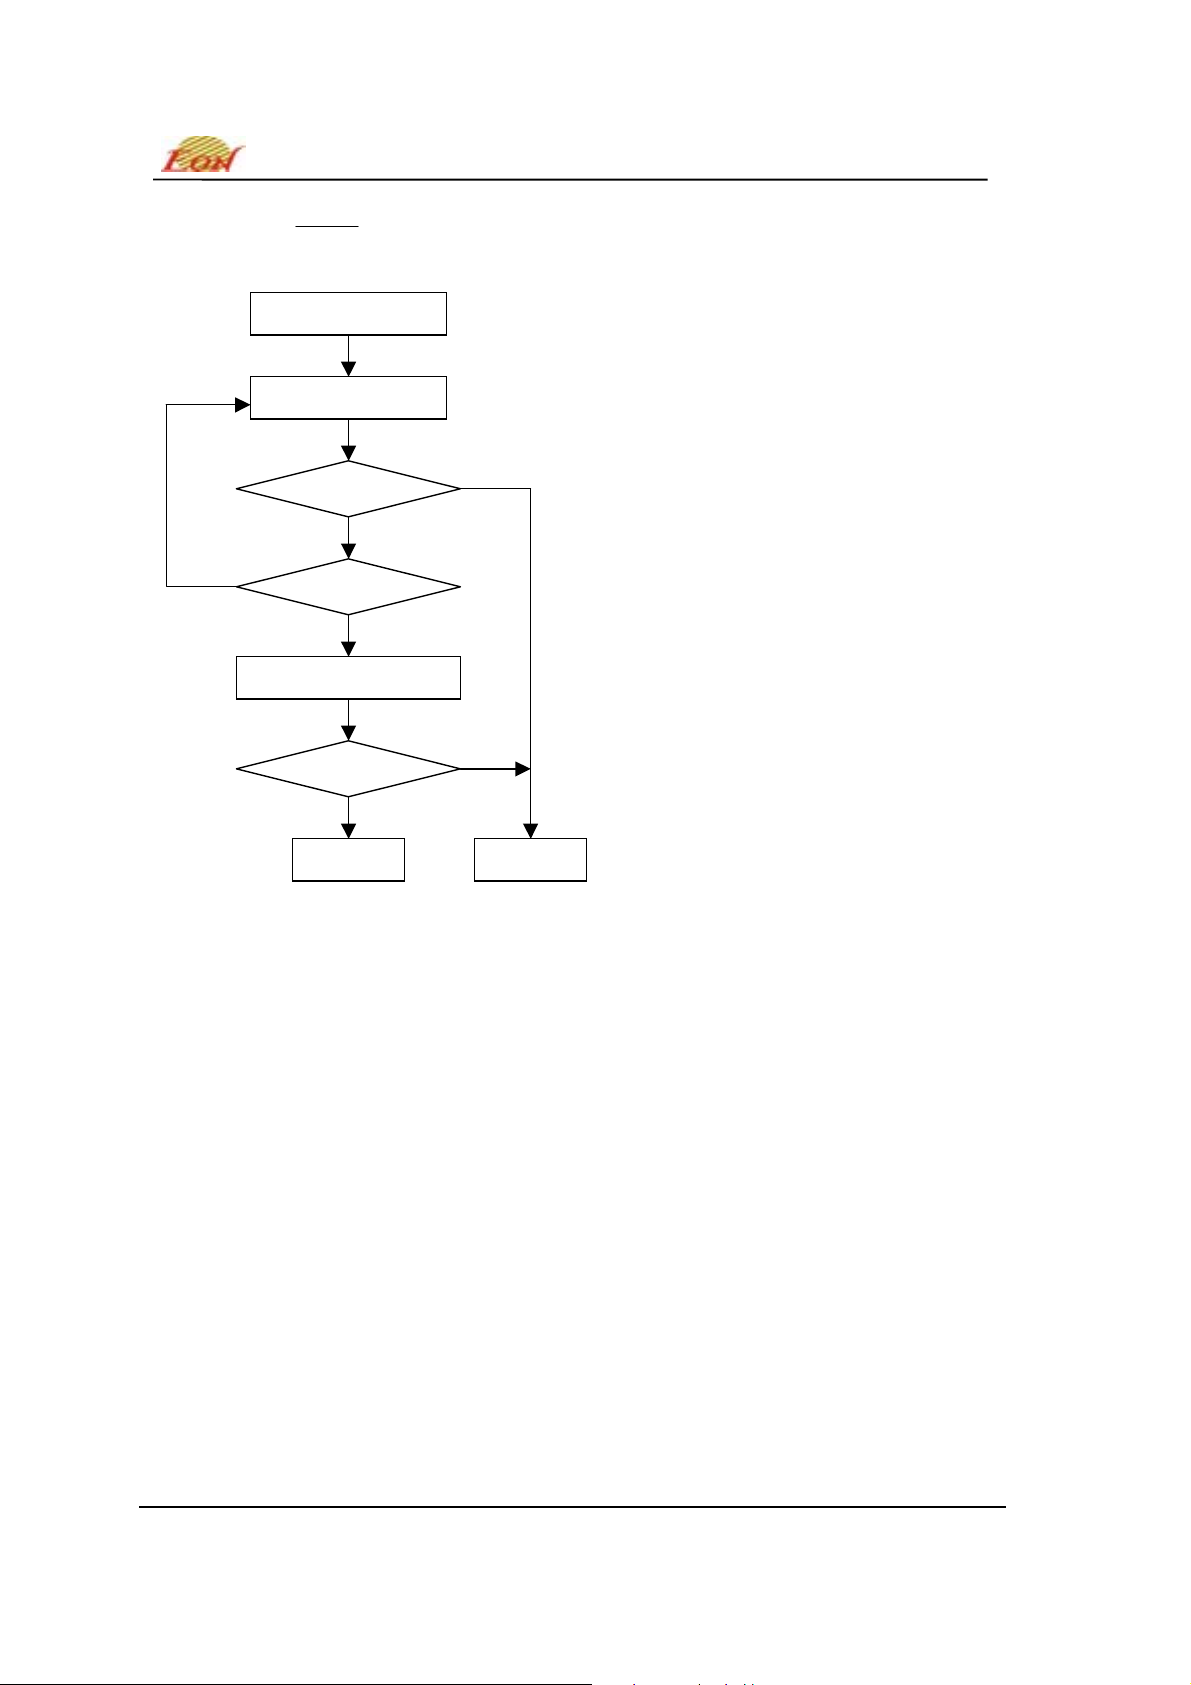
A
Flowchart 5.
DAT
Read Data
Polling Algorithm
Start
EN29F040A
No
DQ7 = Data?
No
DQ5 = 1?
Yes
Read Data
DQ7 = Data?
No
Fail Pass
Yes
Yes
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
18
Rev. B, Issue Date: 2004/04/01
Page 19
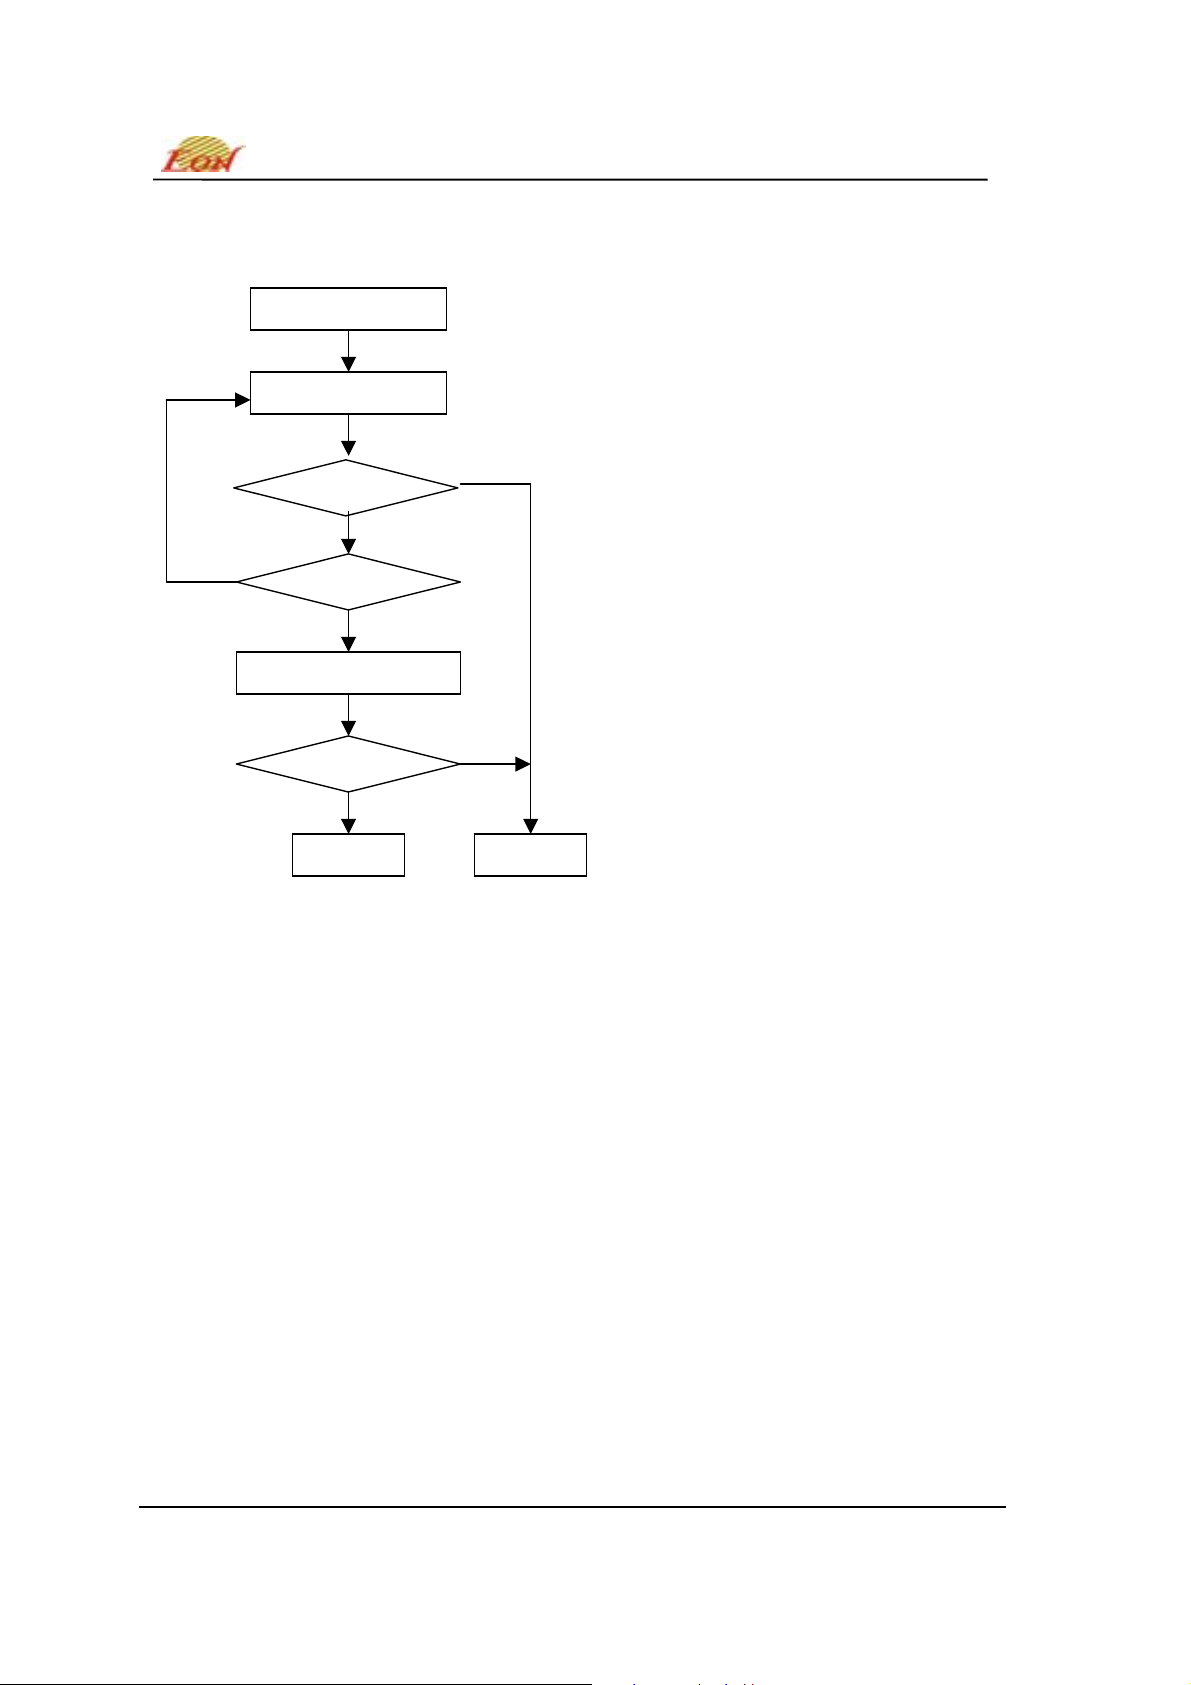
Flowchart 6. Toggle Bit Algorithm
Start
Read Data
EN29F040A
No
DQ6 = Toggle?
No
Yes
DQ5 = 1?
Yes
Read Data
No
DQ6 = Toggle?
Yes
Fail Pass
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
19
Rev. B, Issue Date: 2004/04/01
Page 20
EN29F040A
ABSOLUTE MAXIMUM RATINGS
Storage Temperature
Plastic Packages . . . . . . . . . . . . . . . –65°C to +125°C
Ambient Temperature
with Power Applied. . . . . . . . . . . . . . –55°C to +125°C
Voltage with Respect to Ground
V
(Note 1) . . . . . . . . . . . . . . . . . . . . –0.5 V to 7.0 V
CC
A9, OE# (Note 2) . . . . . . . . . . . . . . . –0.5 V to 11.5 V
All other pins (Note 1) . . . . . . . . . . . . –0.5 V to Vcc+0.5V
Output Short Circuit Current (Note 3) . . . . . . . . . 200 mA
Notes:
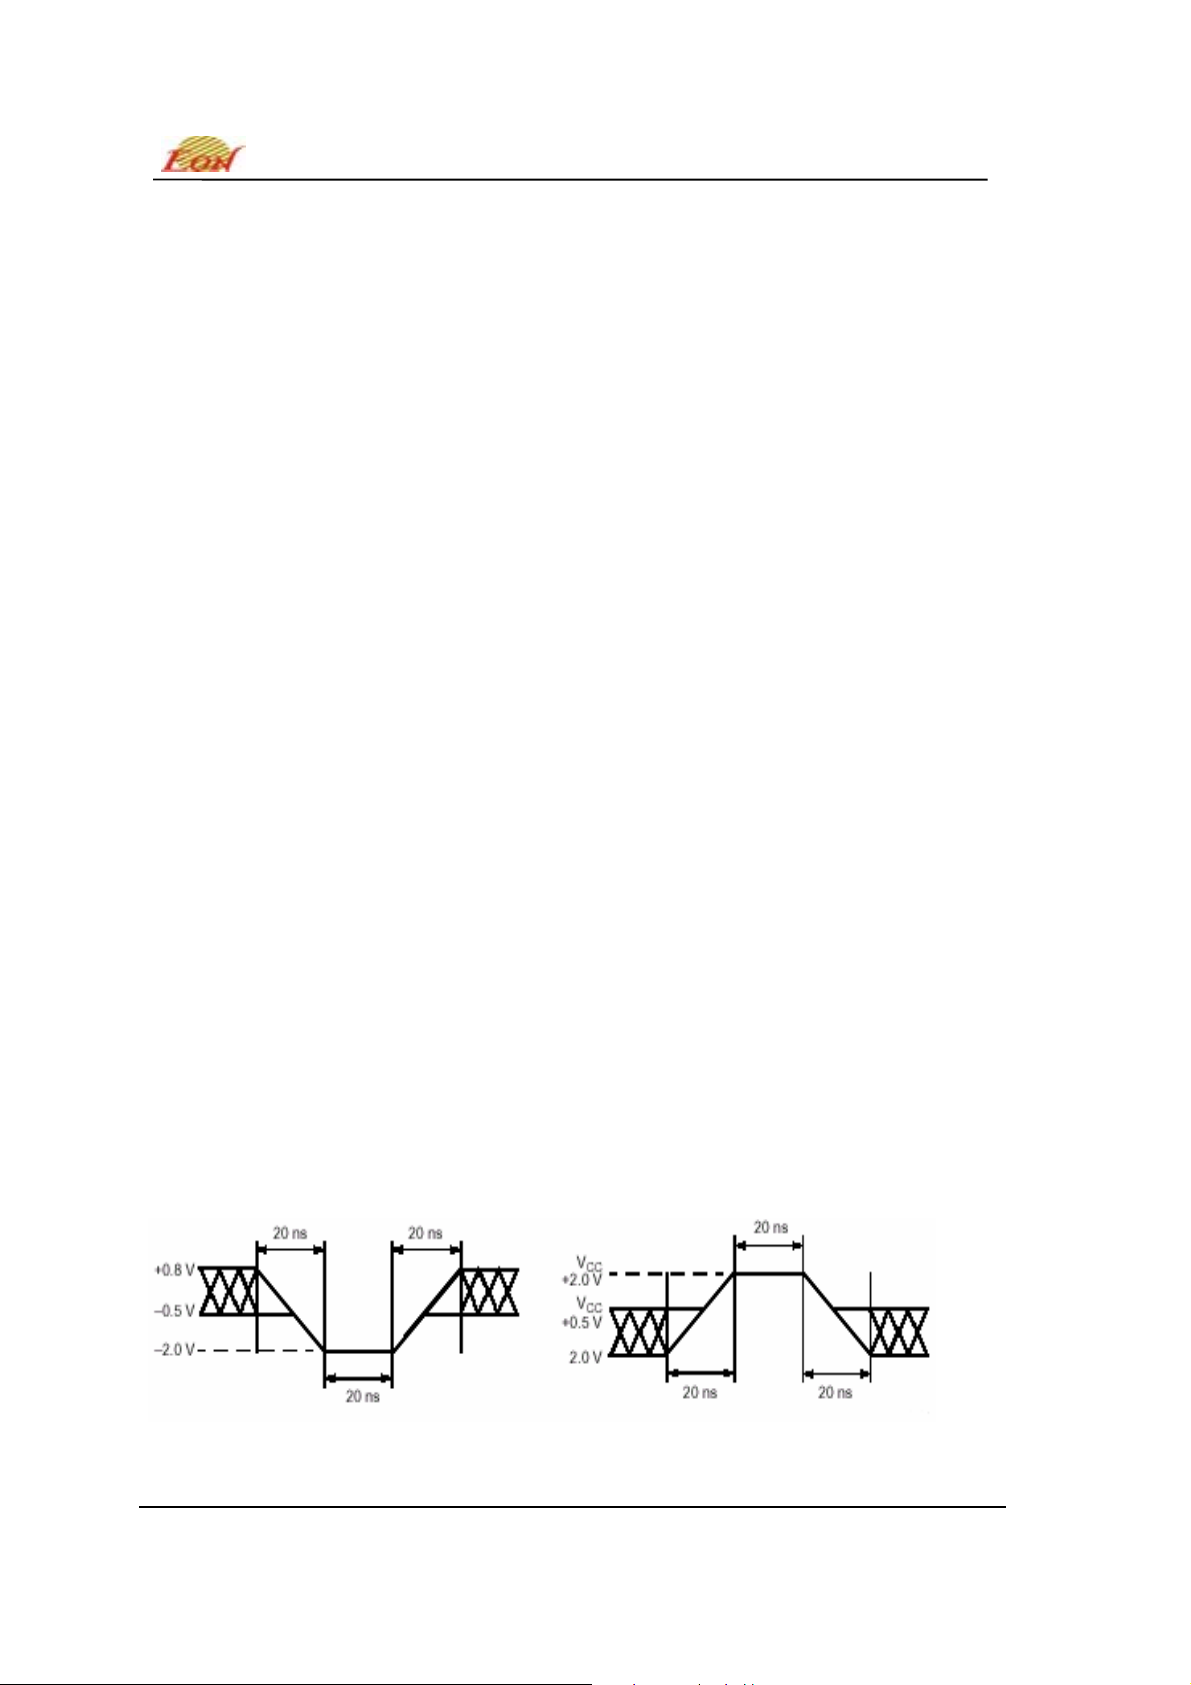
1. Minimum DC voltage on input or I/O pins is –0.5 V. During voltage transitions, inputs may undershoot
V
SS to –1.0V for periods of up to 50 ns and to –2.0 V for periods of up to 20 ns. See Left Figure below.
Maximum DC voltage on input and I/O pins is V
pins may overshoot to V
2. Minimum DC input voltage on A9 pin is –0.5 V. During voltage transitions, A9 and OE# may
undershoot V
Figure. Maximum DC input voltage on A9 and OE# is 11.5 V which may overshoot to 12.5 V for
periods up to 20 ns.
3. No more than one output shorted to ground at a time. Duration of the short circuit should not be greater
than one second. Stresses above those listed under “Absolute Maximum Ratings” may cause
permanent damage to the device. This is a stress rating only; functional operation of the device at
these or any other conditions above those indicated in the operational sections of this specification is
not implied. Exposure of the device to absolute maximum rating conditions for extended periods may
affect device reliability.
SS to –1.0V for periods of up to 50 ns and to –2.0 V for periods of up to 20 ns. See Left
CC + 2.0 V for periods up to 20 ns. See Right Figure below.
OPERATING RANGES
Commercial (C) Devices
Ambient Temperature (T A ) . . . . . . . . . . . 0°C to +70°C
Industrial (I) Devices
Ambient Temperature (T A ). . . . . . . . . . -40°C to +85°C
Supply Voltages
V
CC
for ± 5% devices . . . . . . . . . . . . +4.75 V to +5.25 V
V
CC
V
for ± 10% devices . . . . . . . . . . . +4.50 V to +5.50 V
CC
Operating ranges define those limits between which the
functionality of the device is guaranteed.
CC + 0.5 V. During voltage transitions, input and I/O
Waveform Waveform
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
Maximum Negative Overshoot Maximum Positive Overshoot
20
Rev. B, Issue Date: 2004/04/01
Page 21
EN29F040A
Table 7.
(Ta = 0°C to 70°C or - 40°C to 85°C; VCC = 5.0V ± 10%)
Symbol Parameter Test Conditions Min Max Unit
ILO
I
CC1
I
CC2
I
CC3
I
CC4
VIL
VIH
VOL
VOH
VID
I
V
DC Characteristics
ILI
Output High Voltage CMOS
LIT
LKO
Input Leakage Current
Output Leakage Current
Supply Current (read) TTL Byte
Supply Current (Standby) TTL
Supply Current (Standby) CMOS
Supply Current (Program or Erase)
Input Low Voltage -0.5 0.8 V
Input High Voltage 2
Output Low Voltage
Output High Voltage TTL
A9 Voltage (Electronic Signature) 10.5 11.5 V
A9 Current (Electr onic Signature) A9 = V
Supply voltage (Erase and
Program lock-out)
0V≤ VIN ≤ Vcc
0V≤ V
= VIL; OE = VIH;
CE
CE
Byte program, Sector or Chip
Erase in progress
IOH = -2.5 mA
I
OH
≤ Vcc
OUT
f = 6MHz
= VIH
CE
= Vcc ± 0.3V
IOL = 2 mA
= -100 µA
100 µA
ID
±5 µA
±5 µA
30 mA
1.0 MA
5.0 µA
0.45 V
2.4 V
Vcc -
0.4V
3.2 4.2 V
30
Vcc +
0.5
V
mA
V
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
21
Rev. B, Issue Date: 2004/04/01
Page 22
Table 8. AC CHARACTERISTICS
Read-only Operations Characteristics
Parameter
Symbols
JEDEC Standard
Description
Test Setup
EN29F040A
Speed Options
-45 -55 -70 -90 Unit
t
AVAV
t
AVQV
t
ELQV
t
GLQV
t
EHQZ
t
GHQZ
t
AXQX
t
t
t
t
t
t
t
RC
ACC
CE
OE
DF
DF
OH
Read Cycle Time
Address to Output Delay
Chip Enable To Output Delay
Output Enable to Output Delay
Chip Enable to Output High Z
Output Enable to Output High Z
Output Hold Time from
Addresses,
whichever occurs first
CE
or OE,
Min 45 55 70 90 ns
= V
CE
OE
IL
Max 45 55 70 90 ns
= VIL
Max 45 55 70 90 ns
OE
= VIL
Max 25 30 30 35 ns
Max 10 15 20 20 ns
Max 10 15 20 20 ns
Min 0 0 0 0 ns
Notes:
For -45, -55 Vcc = 5.0V ± 5%
Output Load : 1 TTL gate and 30pF
Input Rise and Fall Times: 5ns
Input Rise Levels: 0.0 V to 3.0 V
Timing Measurement Reference Level, Input and Output: 1.5 V
For all others: Vcc = 5.0V ± 10%
Input Rise and Fall Times: 20 ns
Input Pulse Levels: 0.45 V to 2.4 V
Timing Measurement Reference Level, Input and Output: 0.8 V and 2.0 V
Output Load: 1 TTL gate and 100 pF
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
22
Rev. B, Issue Date: 2004/04/01
Page 23
Table 9. AC CHARACTERISTICS
Write (Erase/Program) Operations
Parameter
Symbols
JEDEC Standard
Description
EN29F040A
Speed Options
-45 -55 -70 -90 Unit
t
AVAV
t
AVWL
t
WLAX
t
DVWH
t
WHDX
t
GHWL
t
ELWL
t
WHEH
t
WLWH
t
WHDL
t
WHWH1
t
t
t
t
t
t
t
t
t
t
t
WHWH1
WC
AS
AH
DS
DH
t
Output Enable Setup Time
OES
t
OEH
GHWL
CS
CH
WP
WPH
Write Cycle Time
Address Setup Time
Address Hold Time
Data Setup Time
Data Hold Time
Output Enable
Hold Time
Read Recovery Time before
Write (
Write Pulse Width High
Programming Ope ration
High to WE Low)
OE
SetupTime
CE
Hold Time
CE
Write Pulse Width
Read
Toggle and
Polling
DATA
Min 45 55 70 90 ns
Min 0 0 0 0 ns
Min 35 45 45 45 ns
Min 20 25 30 45 ns
Min 0 0 0 0 ns
Min 0 0 0 0 ns
MIn 0 0 0 0 ns
Min 10 10 10 10 ns
Min 0 0 0
Min 0 0 0 0 ns
Min 0 0 0 0 ns
Min 25 30 35 45 ns
Min 20 20 20 20 ns
Typ 7 7 7 7 µs
Max 200 200 200 200 µs
0 ns
t
WHWH2
t
WHWH3
t
t
WHWH2
WHWH3
t
VCS
t
VIDR
Sector Erase Operation
Chip Erase Operation
Vcc Setup Time
Rise Time to V
ID
Typ 0.3 0.3 0.3 0.3 s
Max 5 5 5 5 s
Typ 3 3 3 3 s
Max 35 35 35 35 s
Min 50 50 50 50 µs
Min 500 500 500
500 ns
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
23
Rev. B, Issue Date: 2004/04/01
Page 24
Table 10. AC CHARACTERISTICS
Write (Erase/Program) Operations
Alternate
Controlled Writes
CE
Parameter
Symbols
JEDEC Standard
Description
EN29F040A
Speed Options
-45 -55 -70 -90 Unit
t
AVAV
t
AVEL
t
ELAX
t
DVEH
t
EHDX
t
GHEL
t
WLEL
t
EHWH
t
ELEH
t
EHEL
t
WHWH
1
t
t
t
t
t
t
t
t
t
t
t
WHWH1
WC
AS
AH
DS
DH
t
OES
t
OEH
GHEL
WS
WH
CP
CPH
Write Cycle Time
Address Setup Time
Address Hold Time
Data Setup Time
Data Hold Time
Output Enable Setup Time
Output
Enable
Hold Time
Read Recovery Time before
Write (
Write Pulse Width High
Programming Operation
High to CE Low)
OE
SetupTime
WE
Hold Time
WE
Write Pulse Width
Read
Toggle and
Data Polling
Min 45 55 70 90 ns
Min 0 0 0 0 ns
Min 35 45 45 45 ns
Min 20 25 30 45 ns
Min 0 0 0 0 ns
Min 0 0 0 0 ns
0 0 0 0 0 ns
10 10 10 10 10 ns
Min 0 0 0
Min 0 0 0
Min 0 0 0
Min 25 30 35 45 ns
Min 20 20 20 20 ns
Typ 7 7 7 7 µs
Max 200 200 200 200 µs
0 ns
0 ns
0 ns
t
WHWH
2
t
WHWH
3
t
WHWH2
t
WHWH3
t
VCS
t
VIDR
Sector Erase Operation
Chip Erase Operation
Vcc Setup Time
Rise Time to V
ID
Typ 0.3 0.3 0.3 0.3 s
Max 5 5 5 5 s
Typ 3 3 3 3 s
Max 35 35 35 35 s
Min 50 50 50 50 µs
Min 500 500 500
500 ns
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
24
Rev. B, Issue Date: 2004/04/01
Page 25
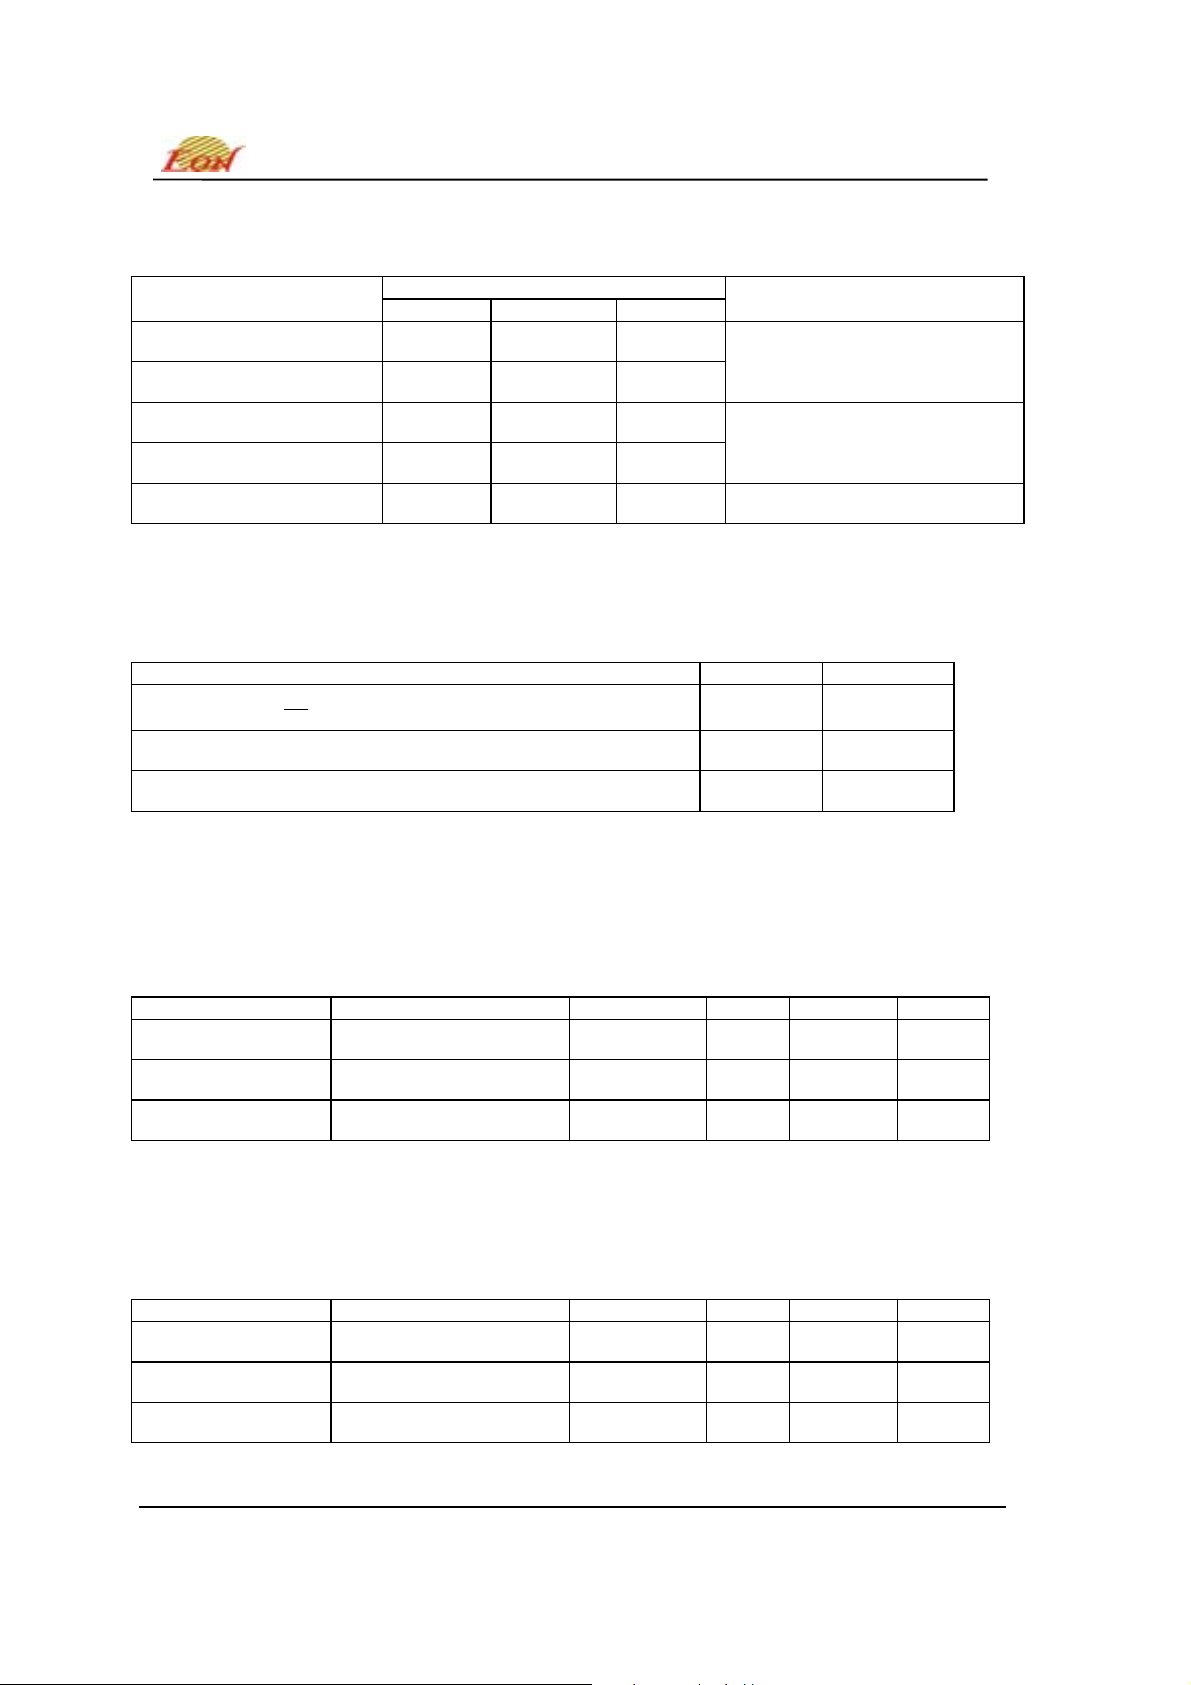
Table 11. ERASE AND PROGRAMMING PERFORMANCE
Parameter
Sector Erase Time 0.3 5 sec
Chip Erase Time 3 35 sec
Byte Programming Time 7 200 µs
Chip Programming Time 2 5 sec
Limits
Typ Max Unit
Excludes 00H programming prior to
Excludes system level overhead
EN29F040A
Comments
erasure
Erase/Program Endurance 100K cycles
Minimum 100K cycles guaranteed
Table 12. LATCH UP CHARACTERISTICS
Parameter Description Min Max
Input voltage with respect to Vss on all pins except I/O pins
(including A9 and
Input voltage with respect to Vss on all I/O Pins -1.0 V Vcc + 1.0 V
Vcc Current -100 mA 100 mA
OE
)
-1.0 V 12.0 V
Note : These are latch up characteristics and the device should never be put under
these conditions. Refer to Absolute Maximum ratings for the actual operating limits.
Table 13. 32-PIN PLCC PIN CAPACITANCE @ 25°C, 1.0MHz
Parameter Symbol Parameter Description Test Setup Typ Max Unit
CIN
C
OUT
Input Capacitance
Output Capacitance
VIN = 0
V
OUT
= 0
4 6 pF
8 12 pF
C
IN2
Control Pin Capacitance
VIN = 0
8 12 pF
Table 14. 32-PIN TSOP PIN CAPACITANCE @ 25°C, 1.0MHz
Parameter Symbol Parameter Description Test Setup Typ Max Unit
CIN
C
C
OUT
IN2
Input Capacitance
Output Capacitance
Control Pin Capacitance
VIN = 0
V
OUT
VIN = 0
= 0
6 7.5 pF
8.5 12 pF
7.5 9 pF
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
25
Rev. B, Issue Date: 2004/04/01
Page 26
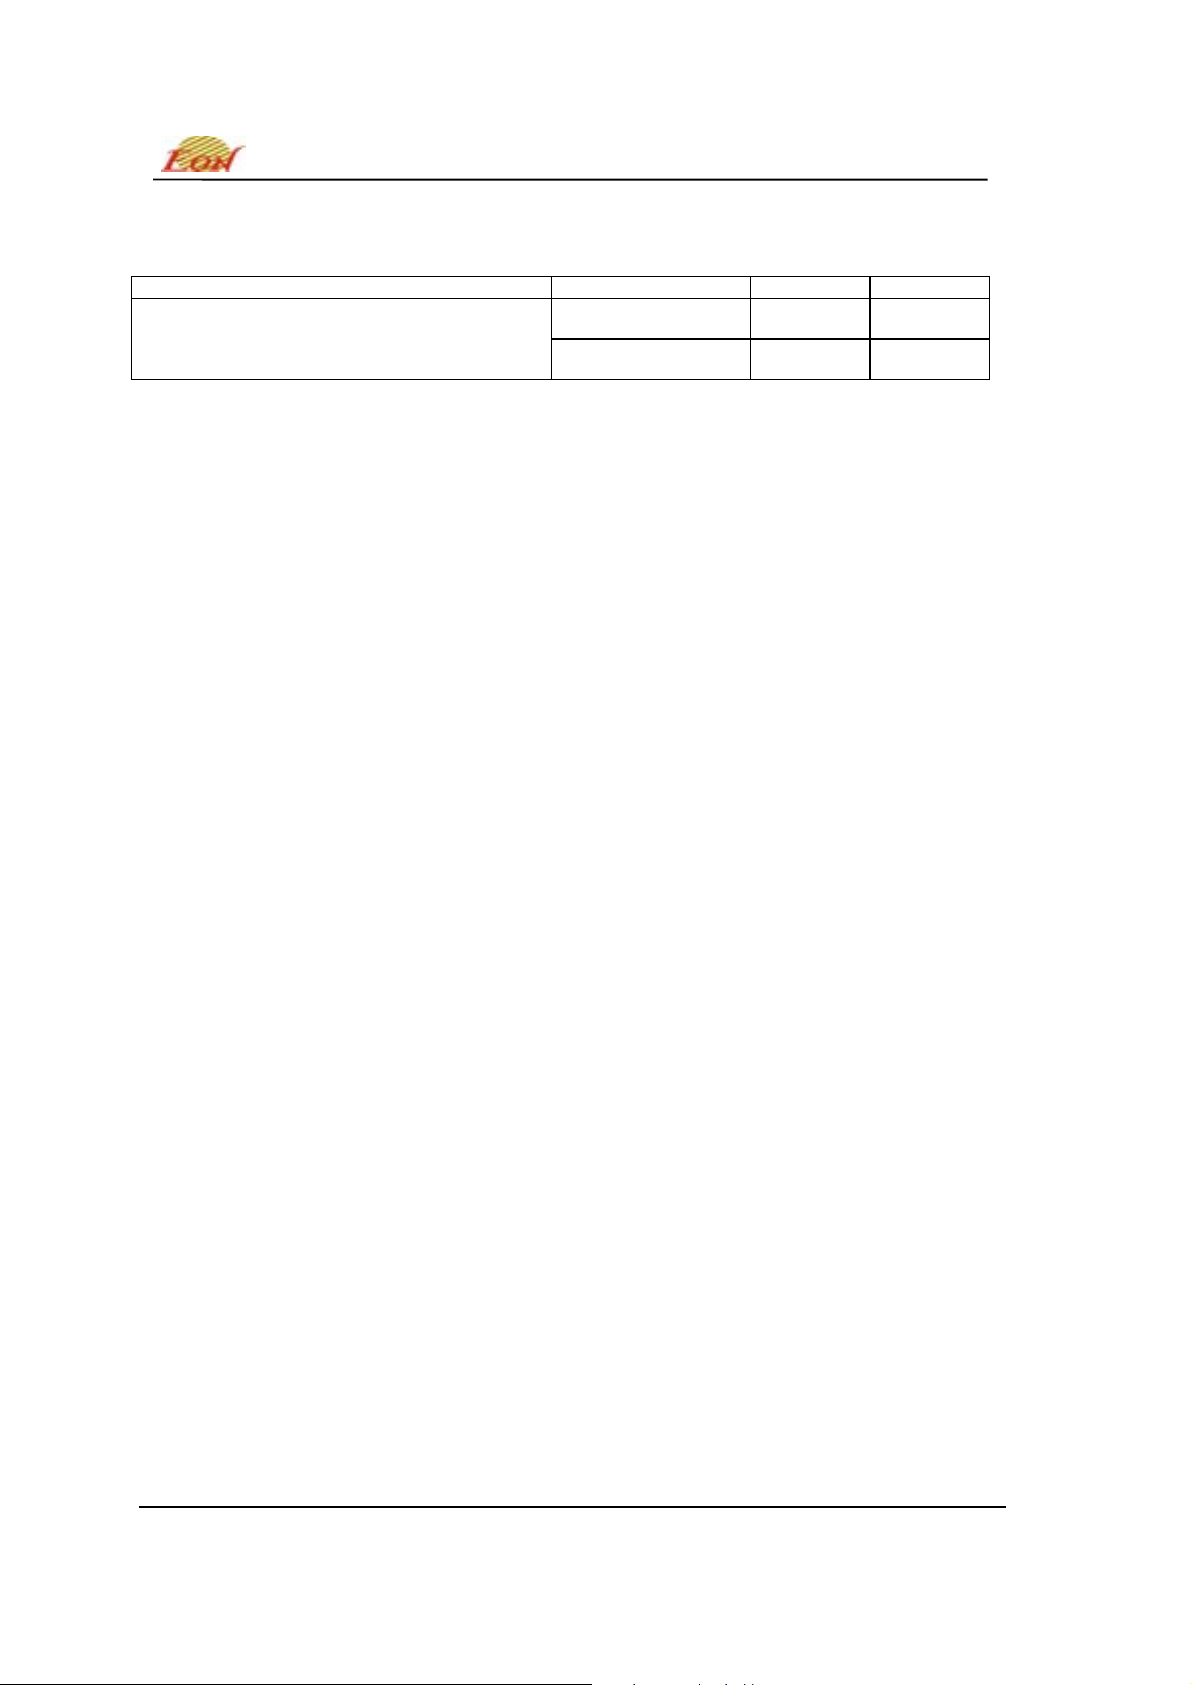
Table 15. DATA RETENTION
Parameter Description Test Conditions Min Unit
Minimum Pattern Data Retention Time
EN29F040A
150°C 10 Years
125°C 20 Years
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
26
Rev. B, Issue Date: 2004/04/01
Page 27
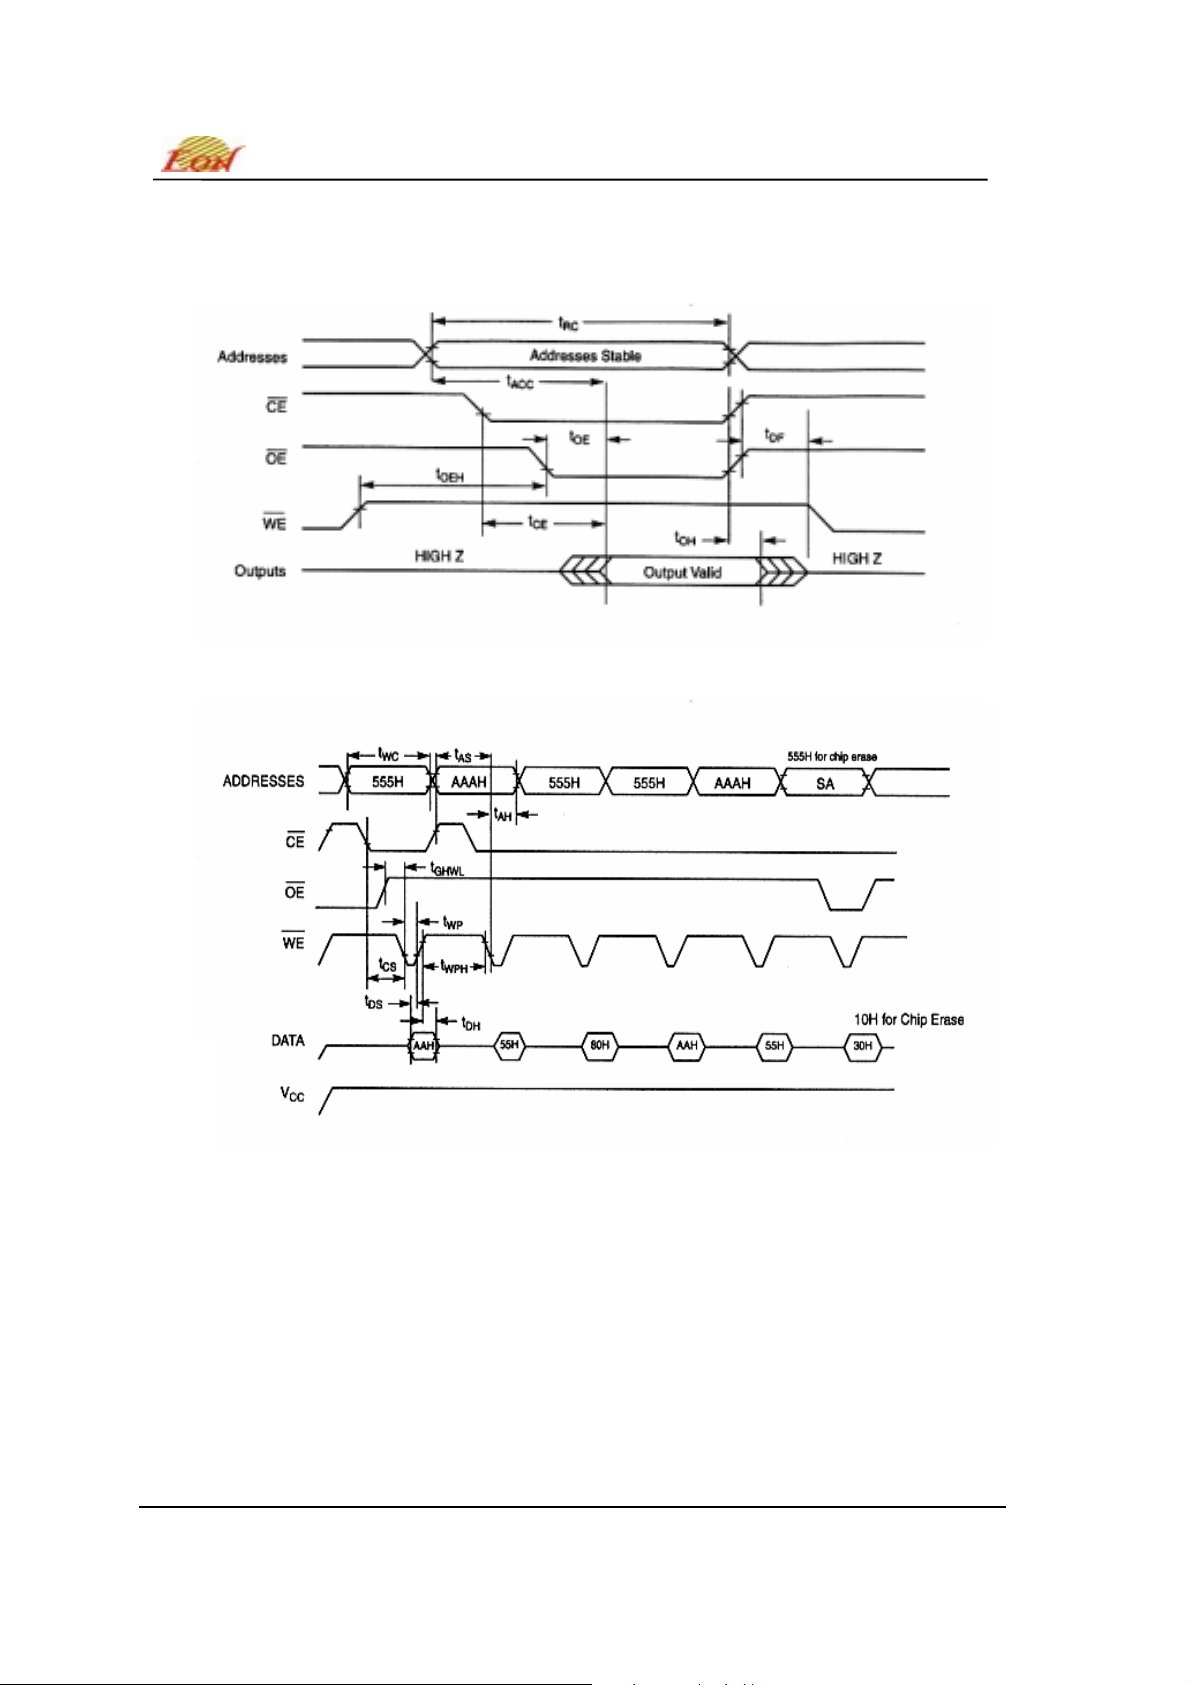
SWITCHING WAVEFORMS
Figure 5. AC Waveforms for READ Operations
Figure 6. AC Waveforms for Chip/Sector Erase Operations
EN29F040A
Notes:
1. SA is the Sector address for Sector erase.
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
27
Rev. B, Issue Date: 2004/04/01
Page 28
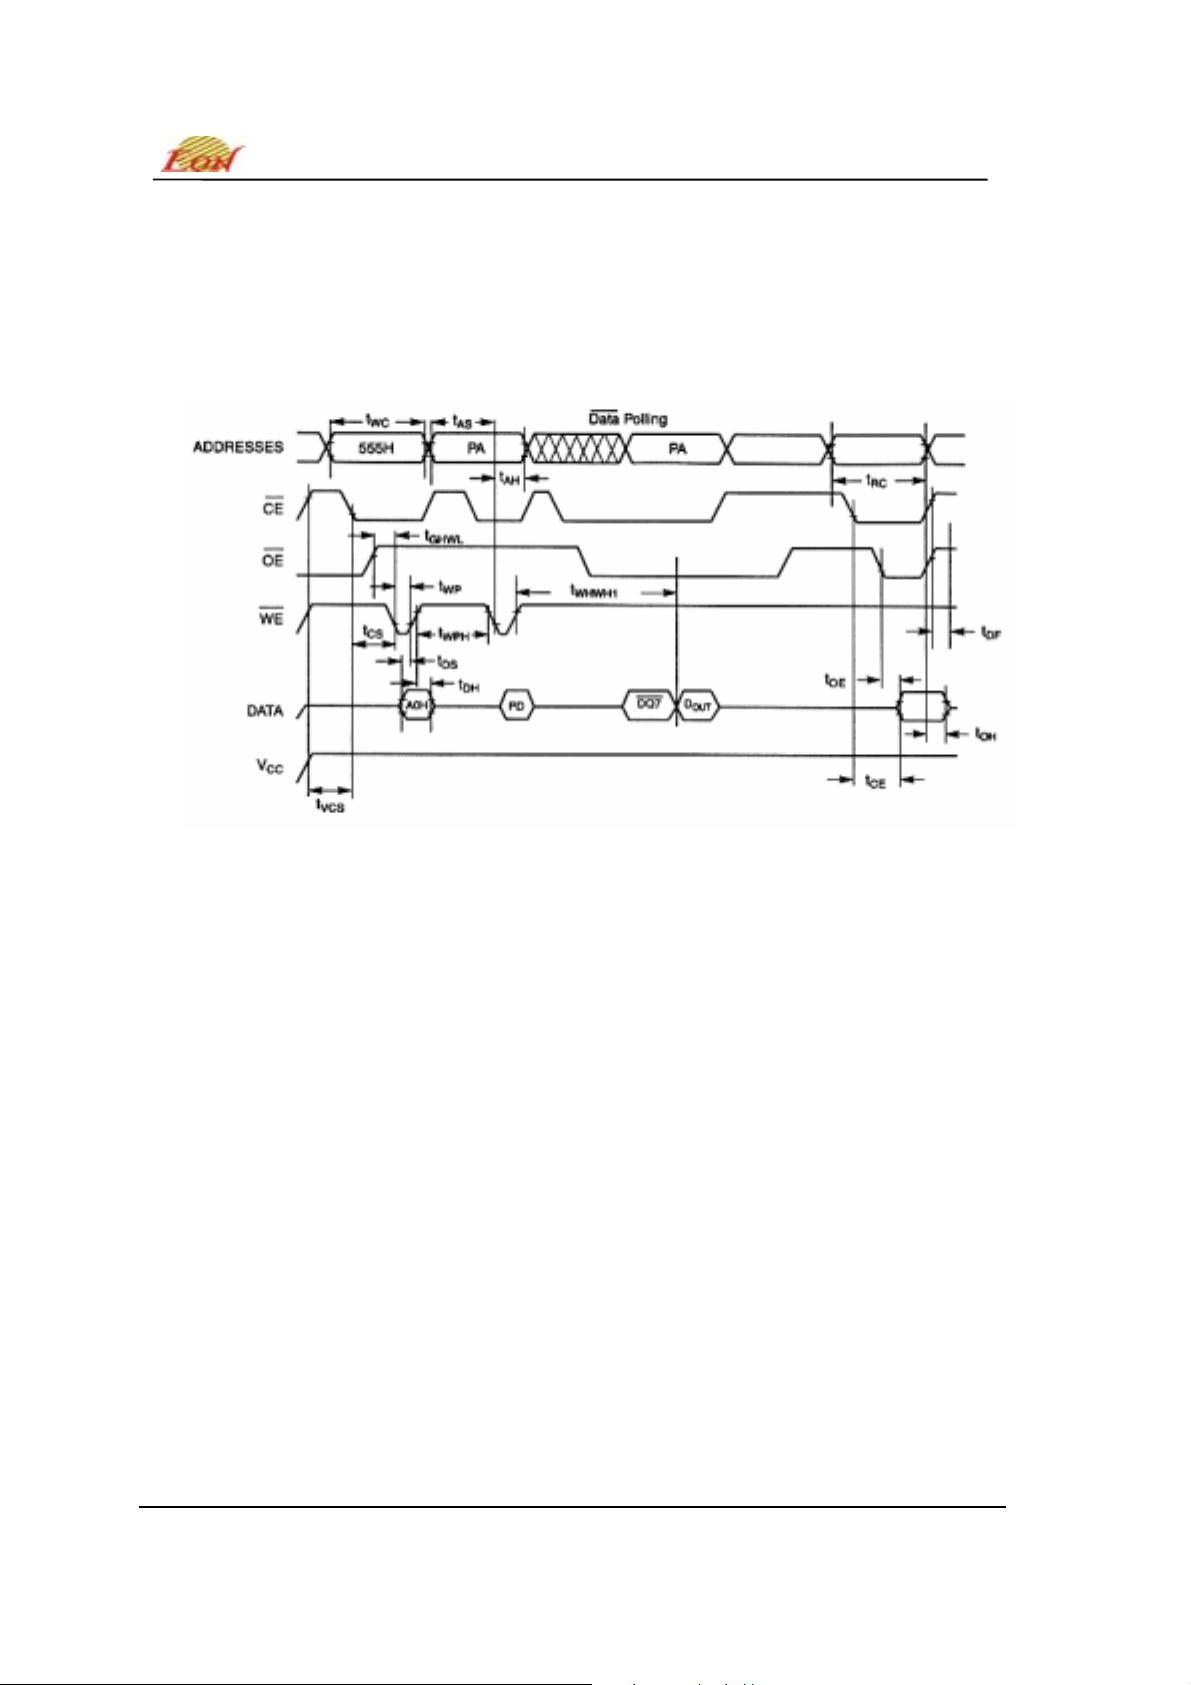
SWITCHING WAVEFORMS (continued)
Figure 7. Program Operation Timings
EN29F040A
Notes:
1. PA is address of the memory location to be programmed.
2. PD is data to be programmed at byte address.
3. /DQ7 is the output of the complement of the data written to the device.
4. D
5. Figure indicates last two bus cycles of four bus cycle sequence.
is the output of data written to the device.
OUT
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
28
Rev. B, Issue Date: 2004/04/01
Page 29
EN29F040A
Figure 8. AC Waveforms for /DATA Polling During Embedded Algorithm
Operations
Notes:
*DQ
= Valid Data (The device has completed the embedded operation).
7
Figure 9. AC Waveforms for Toggle Bit During Embedded Algorithm
Operations
Notes:
*DQ6 stops toggling (The device has completed the embedded operation).
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
29
Rev. B, Issue Date: 2004/04/01
Page 30
SWITCHING WAVEFORMS (continued)
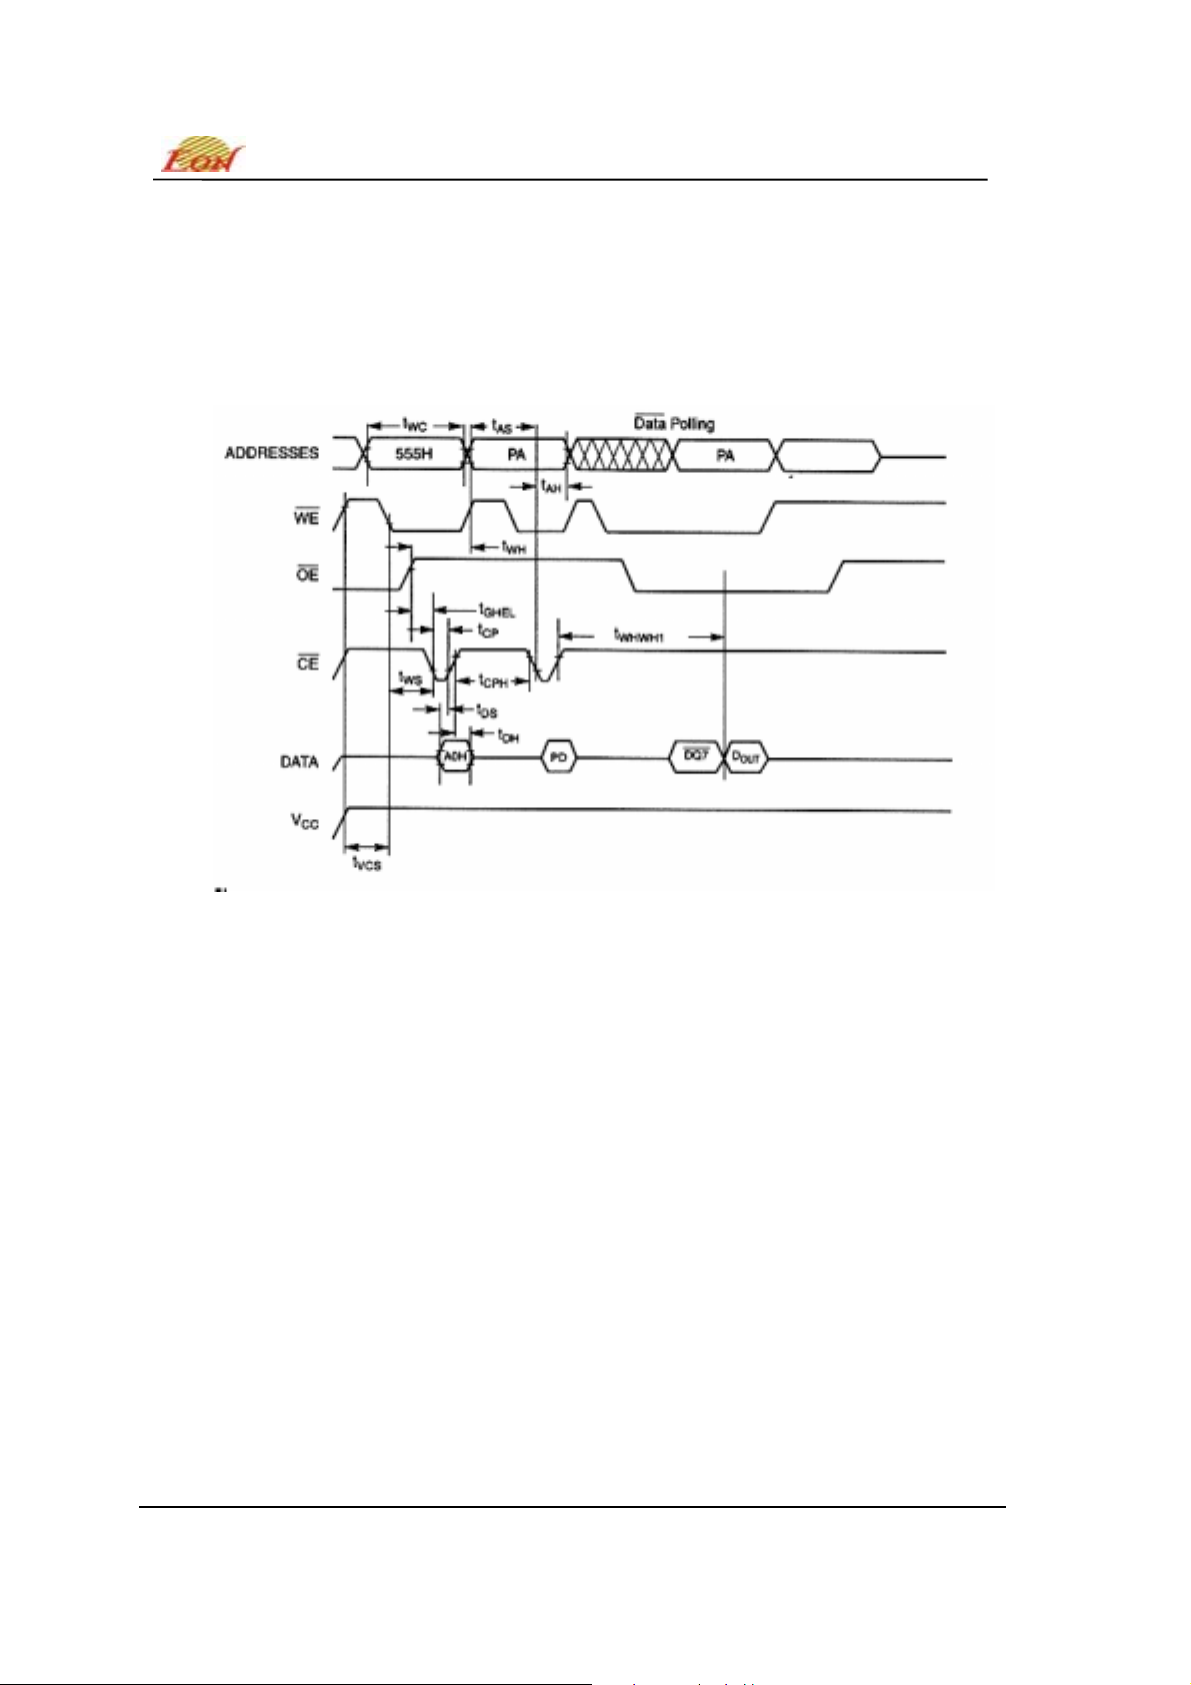
Figure 10. Alternate /CE Controlled Write Operation Timings
EN29F040A
Notes:
1. PA is address of the memory location to be programmed.
2. PD is data to be programmed at byte address.
3. /DQ7 is the output of the complement of the data written to the device.
4. D
5. Figure indicates last two bus cycles of four bus cycle sequence.
is the output of data written to the device.
OUT
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
30
Rev. B, Issue Date: 2004/04/01
Page 31
EN29F040A
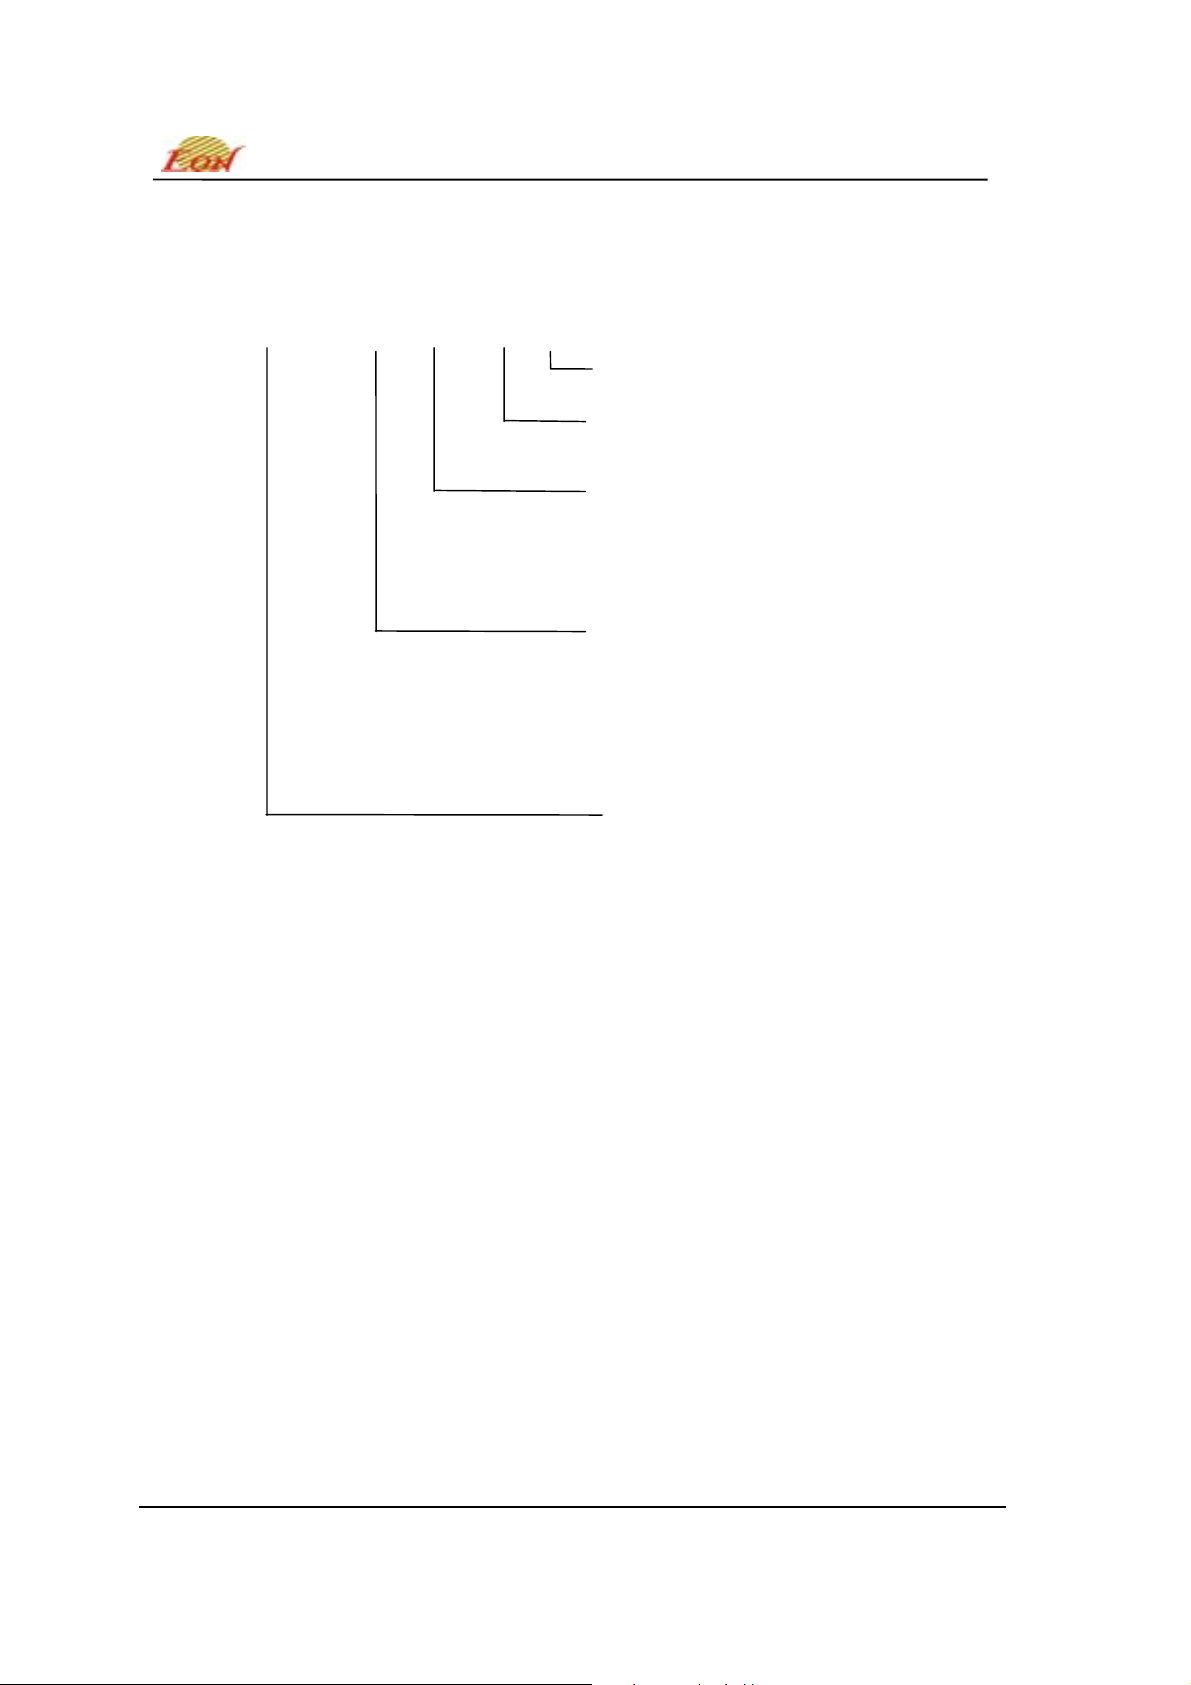
ORDERING INFORMATION
EN29F040A - 45 P C P
PACKAGING CONTENT
Blank= Conventional
P=Pb free
TEMPERATURE RANGE
C = Commercial (0°C to +70°C)
I = Industrial (-40°C to +85°C)
PACKAGE
P = 32 Plastic DIP
J = 32 Plastic PLCC
T = 32 Plastic TSOP
SPEED
45 = 45ns
55 = 55ns
70 = 70ns
90 = 90ns
BASE PART NUMBER
EN = EON Silicon Solution Inc.
29F = FLASH, 5V
040 = 512K x 8
A = version A
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
31
Rev. B, Issue Date: 2004/04/01
Page 32
PHYSICAL DIMENSIONS
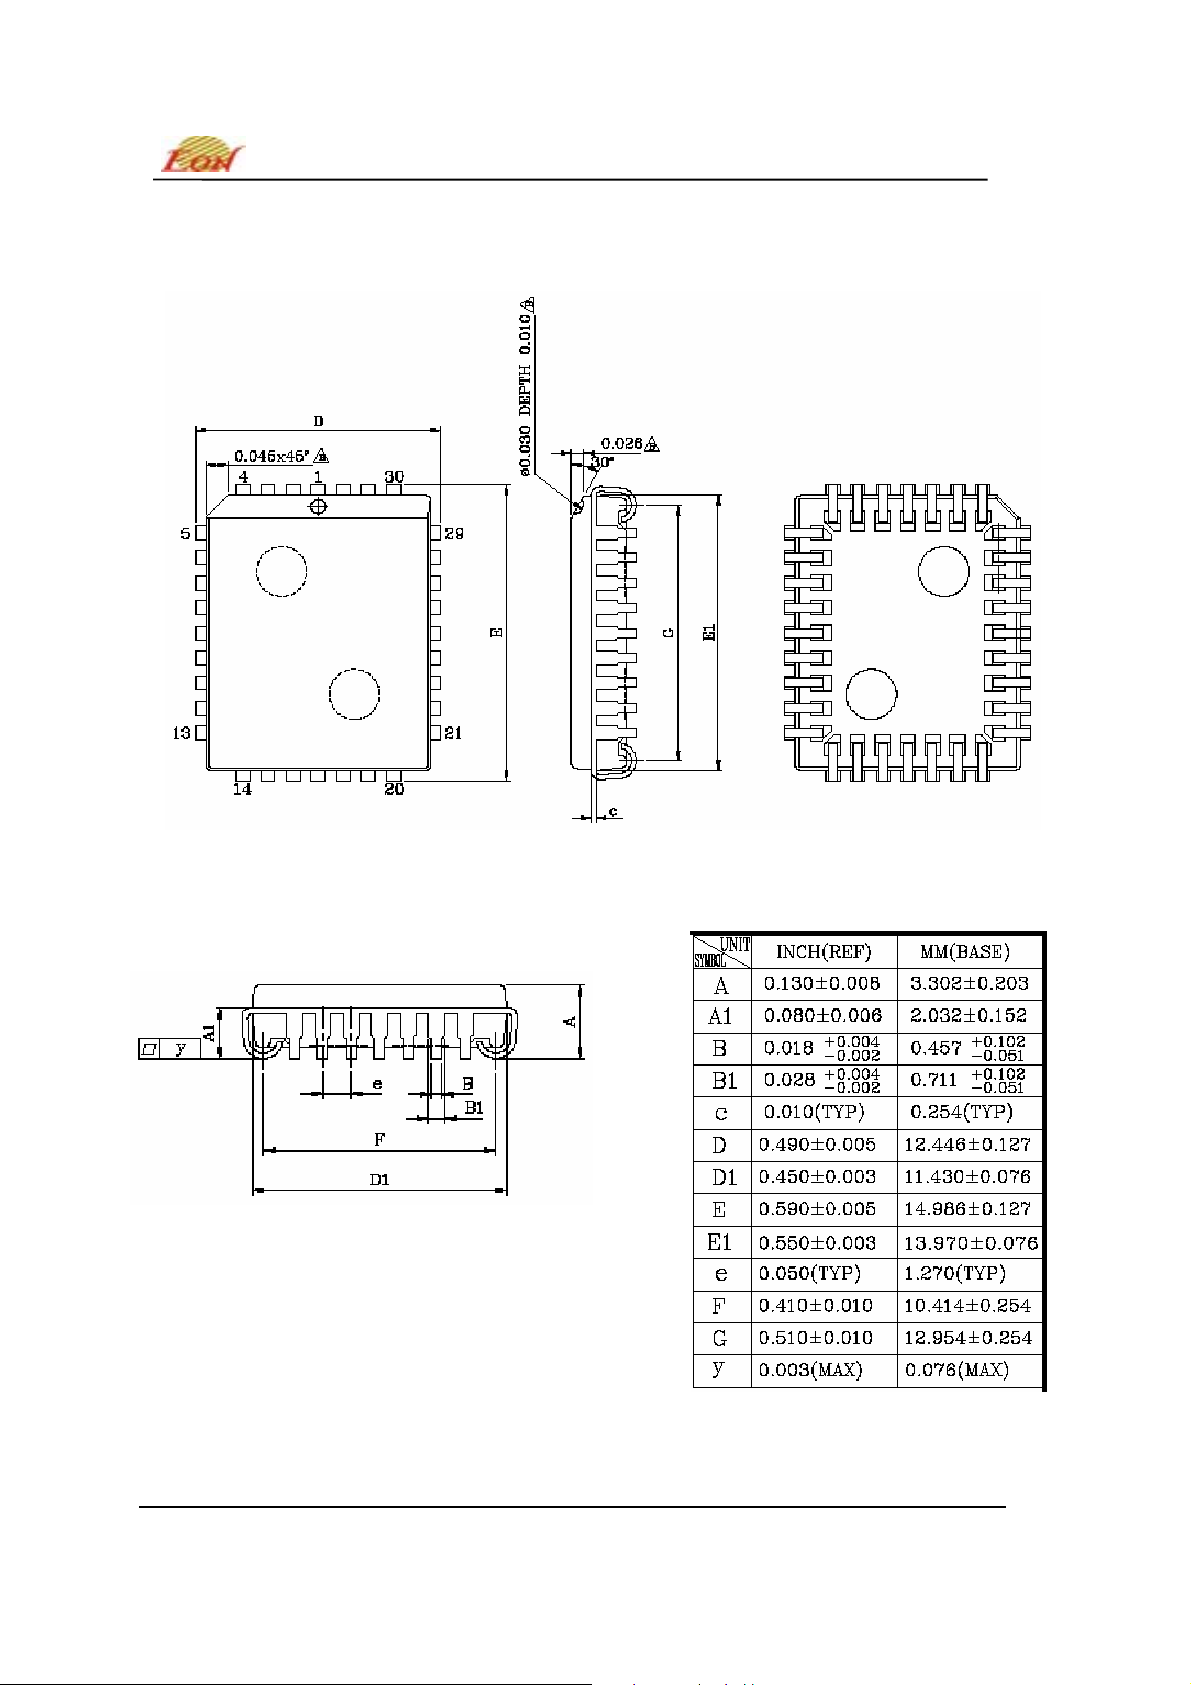
PL 032
— 32-Pin Plastic Leaded Chip Carrier
EN29F040A
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
32
Rev. B, Issue Date: 2004/04/01
Page 33
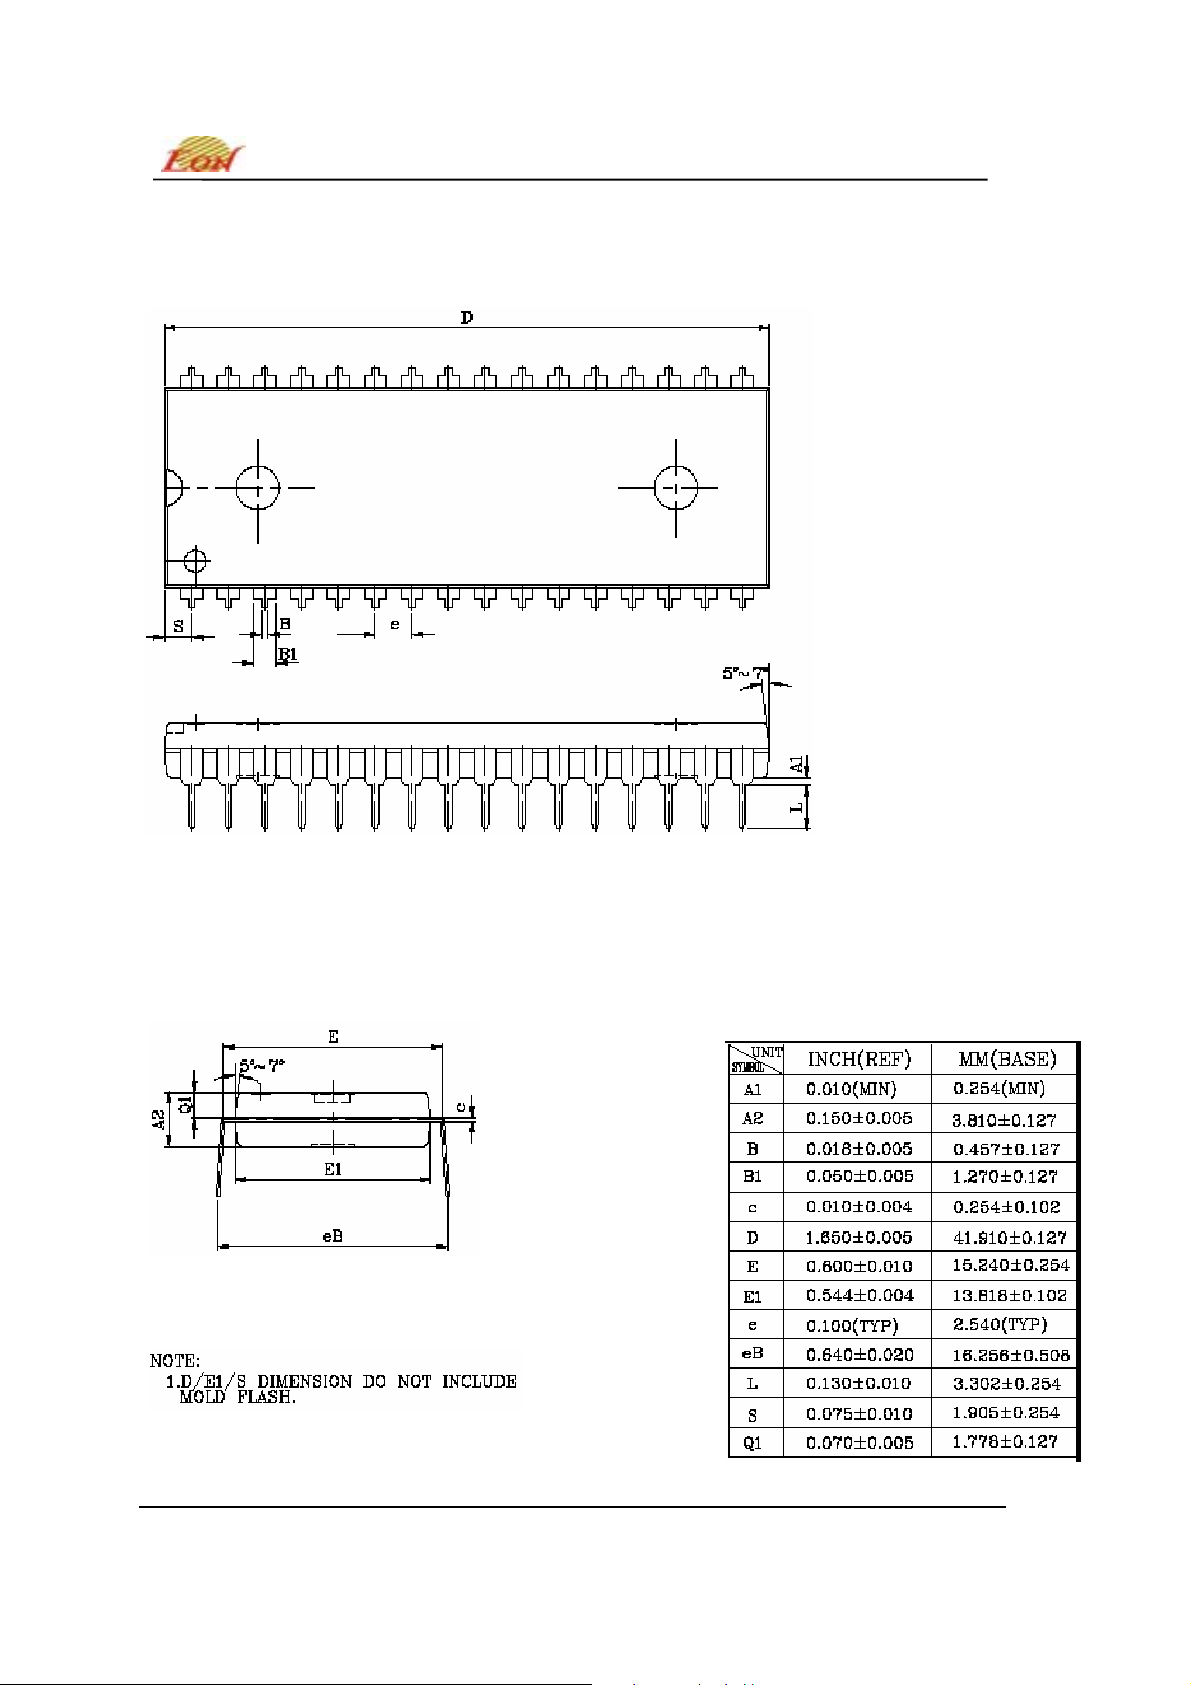
PHYSICAL DIMENSIONS (continued)
PD 032
— 32-Pin Plastic DIP
EN29F040A
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
33
Rev. B, Issue Date: 2004/04/01
Page 34
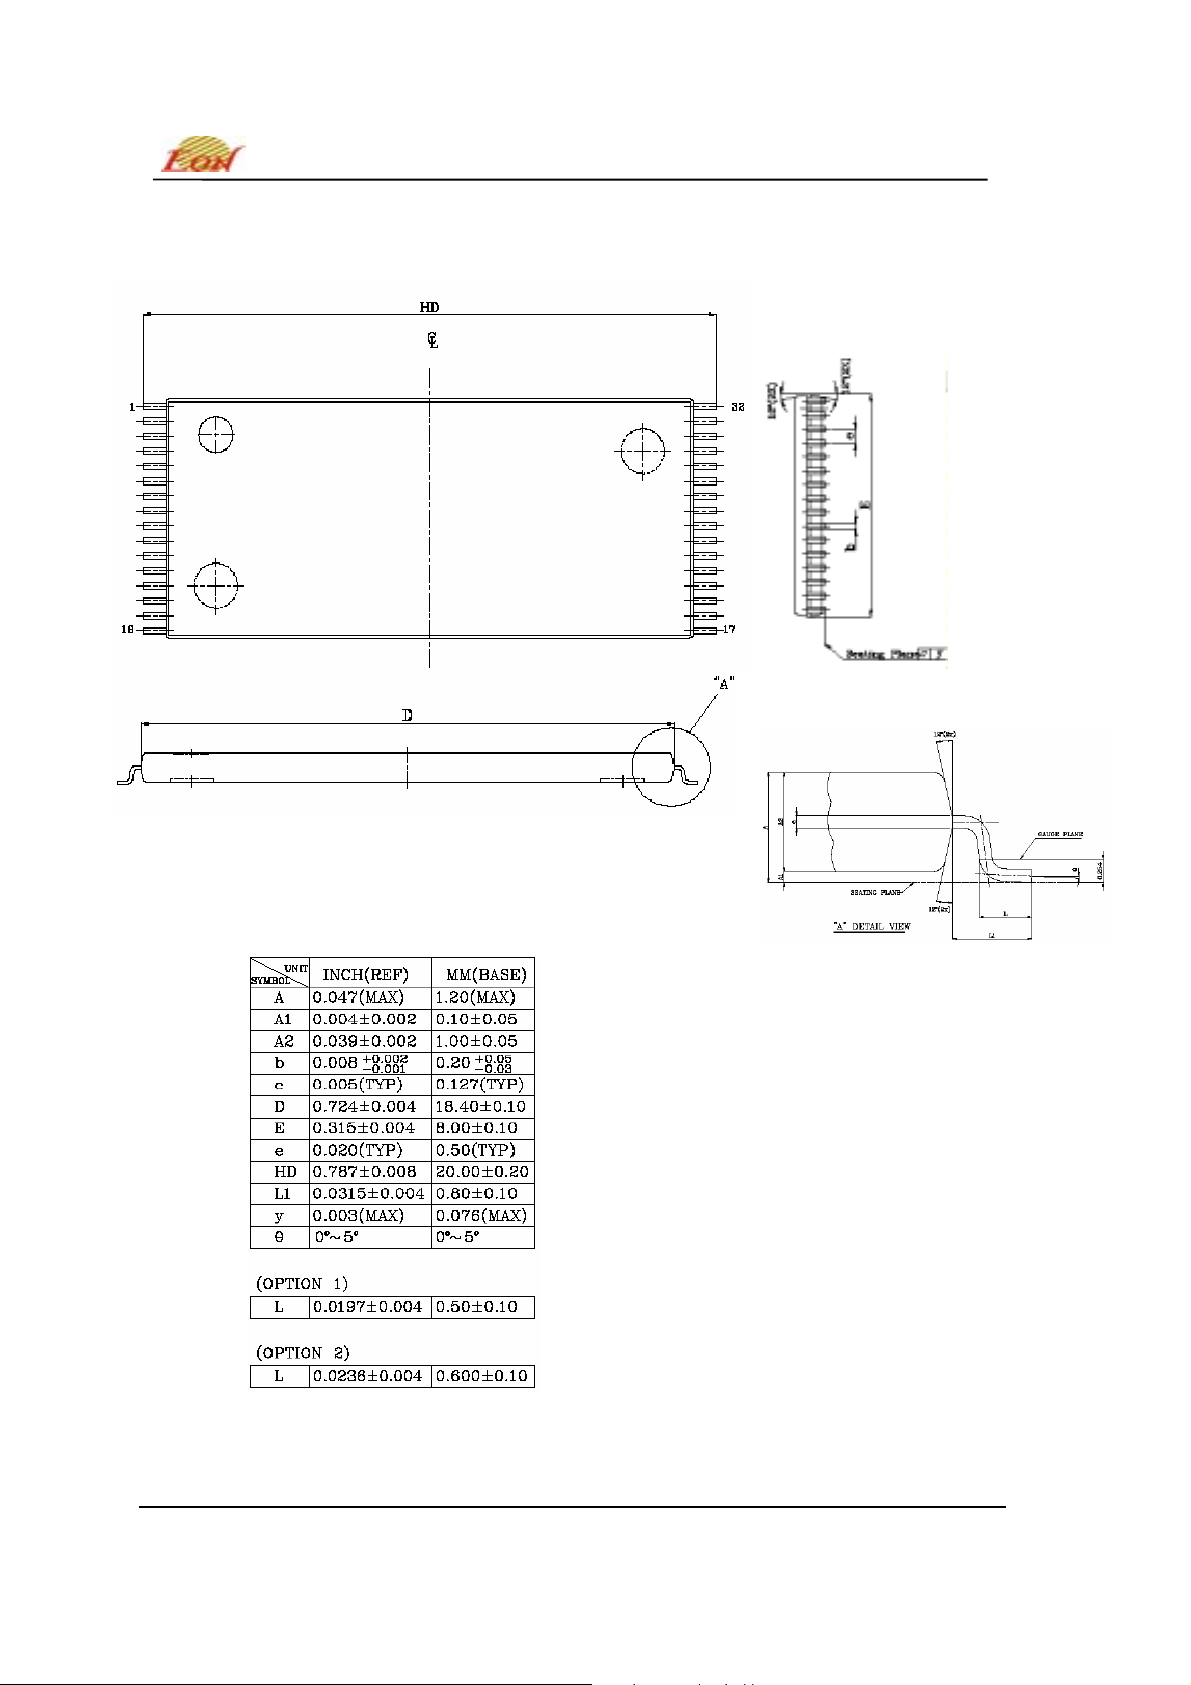
PHYSICAL DIMENSIONS (continued)
TS 032
— 32-Pin Standard Thin Small
EN29F040A
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
34
Rev. B, Issue Date: 2004/04/01
Page 35
EN29F040A
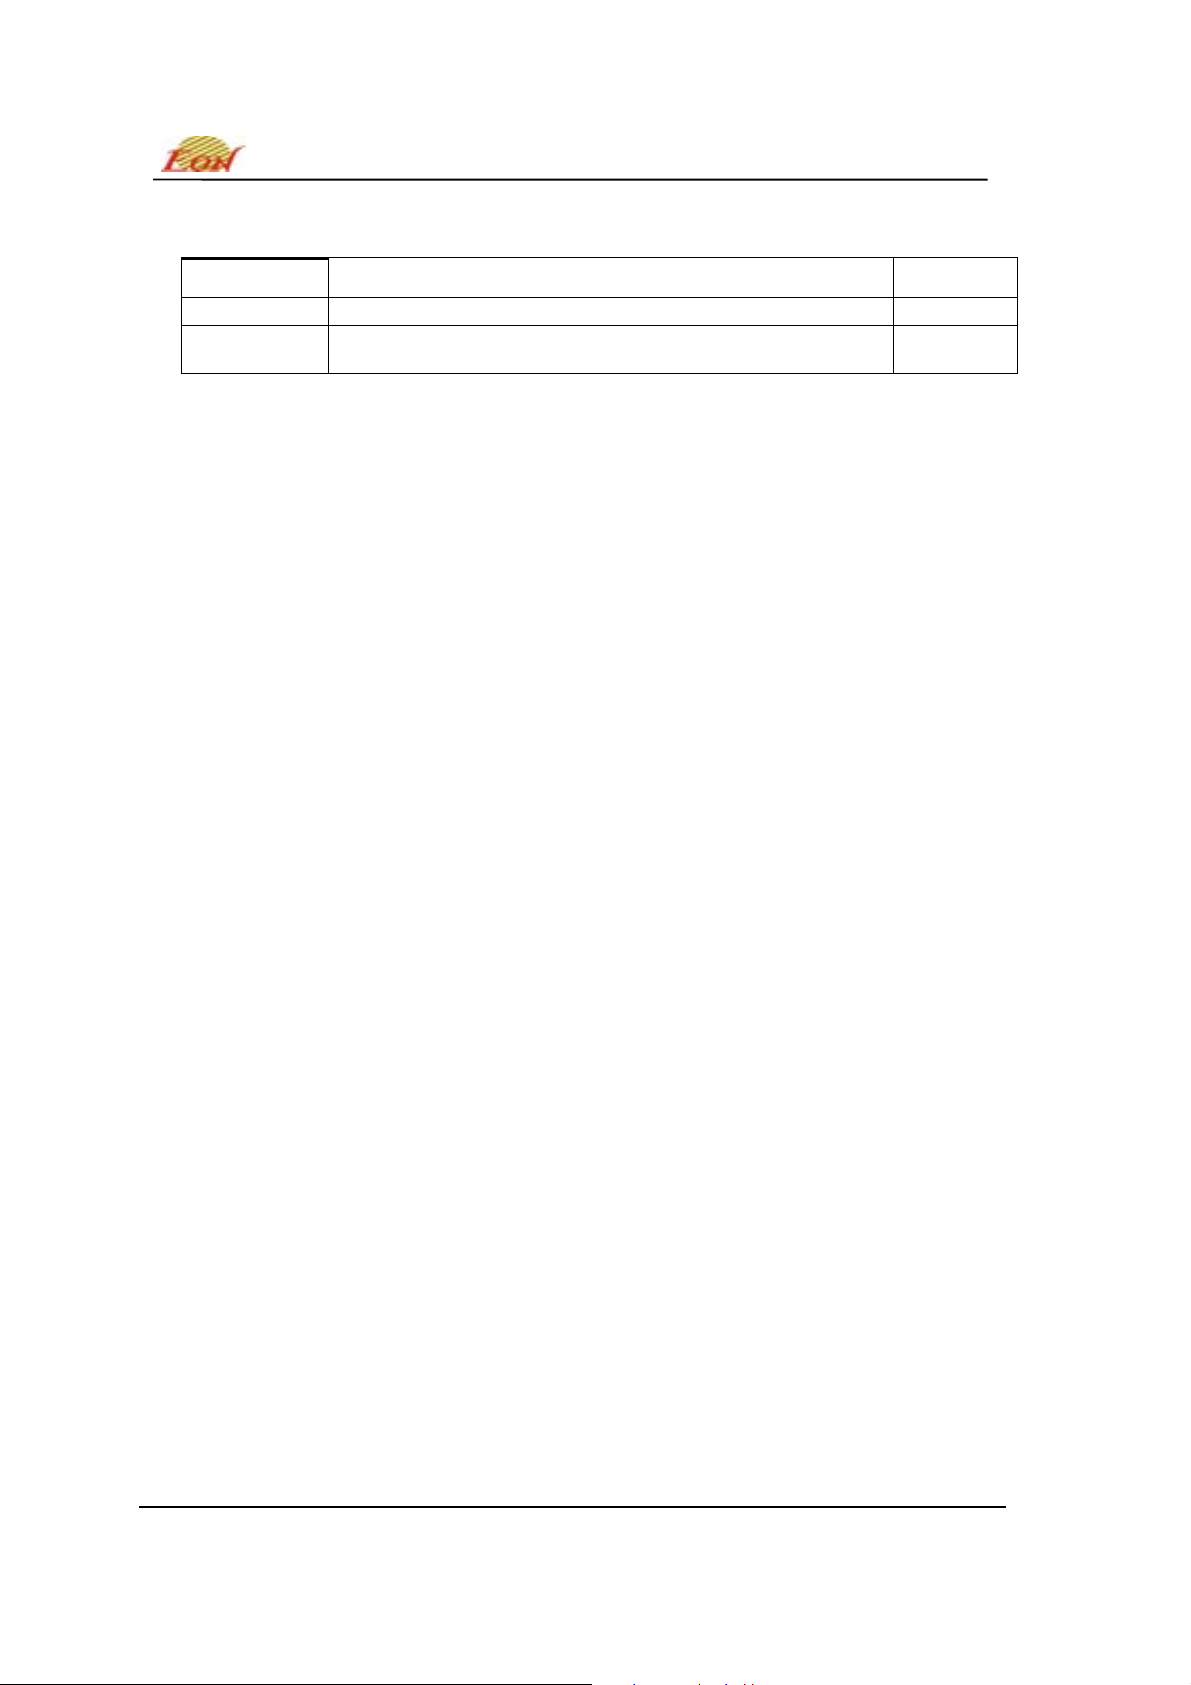
Revisions List
Revision No
A Initial draft 2003/04/03
B Correct a typo of table 5 on page 8.
Description Date
2004/04/01
Address bits A18-A16 uniquely select any Sector
This Data Sheet may be revised by subsequent versions ©2003 Eon Silicon Solution, Inc., www.essi.com.tw
or modifications due to changes in technical specifications.
35
Rev. B, Issue Date: 2004/04/01
 Loading...