

Page 1

Page 1 of 76
LINAK.COM/TECHLINE
Actuator LA25
User manual
Page 2

Page 2 of 76
Contents
Preface ................................................................................................................................................. 4
LINAK application policy ........................................................................................................................ 5
Chapter 1
Safety instructions .............................................................................................................................. 6-7
IECEx/ATEX ........................................................................................................................................ 8-9
Chapter 2
Mounting guidelines....................................................................................................................... 10-11
Mounting of cables ............................................................................................................................. 12
Electrical installation: ........................................................................................................................... 13
Recommended fuse ................................................................................................................... 13
Actuator without feedback ........................................................................................................ 14
Actuator with:
Endstop signal output ................................................................................................ 15-16
Relative positioning - Single Hall ................................................................................ 17-18
Endstop signals and relative positioning - Single Hall .................................................. 19-20
Absolute positioning - Analogue feedback ..................................................................21-22
Endstop signals and absolute positioning - Analogue feedback ................................... 23-24
Absolute positioning - PWM ...................................................................................... 25-26
Endstop signals and absolute positioning - PWM ....................................................... 27-28
IC Basic ..................................................................................................................... 29-31
IC Advanced - with BusLink ........................................................................................ 32-35
Correct wiring of Power GND and Signal GND for IC Basic and IC Advanced .............................. 35
IC options overview .................................................................................................................. 36
Feedback configurations available for IC Basic, IC Advanced and Parallel .................................... 37
Actuator configurations available for IC Basic, IC Advanced and Parallel ................................ 38-39
Actuator with Parallel ...........................................................................................................40-42
The parallel system ...............................................................................................................43-45
System monitoring for Parallel ................................................................................................... 46
Alignment of the parallel actuator system .................................................................................. 46
Parallel manual service mode .................................................................................................... 47
Actuator with CAN bus ........................................................................................................ 48-50
Page 3

Page 3 of 76
Contents
Chapter 3
Troubleshooting ............................................................................................................................. 51-52
Troubleshooting for Parallel ............................................................................................................53-54
BusLink service counter - Reason for last stop ...................................................................................... 55
Chapter 4
Specifications ...................................................................................................................................... 56
Usage ................................................................................................................................................. 56
Actuator dimensions............................................................................................................................ 57
Speed and current curves: ...............................................................................................................58-59
12V motor ................................................................................................................................... 58
24V motor ................................................................................................................................... 59
Test of conducted and radiated emission .............................................................................................. 60
Label for LA25 .................................................................................................................................... 61
Label for LA25 IECEx/ATEX .................................................................................................................. 62
Key to symbols .................................................................................................................................... 63
LA25 ordering example ....................................................................................................................... 64
Chapter 5
Maintenance ....................................................................................................................................... 65
Repair ................................................................................................................................................. 65
Main groups of disposal ...................................................................................................................... 65
Warranty ............................................................................................................................................ 65
Declaration of conformity .................................................................................................................... 66
Declaration of incorporation of partly completed machinery .................................................................. 67
IECEx certificates ............................................................................................................................ 68-69
ATEX ..............................................................................................................................................69-72
Adresses ............................................................................................................................................. 74
Page 4

Page 4 of 76
Preface
Dear User,
We are delighted that you have chosen a product from LINAK®.
LINAK systems are high-tech products based on many years of experience in the manufacture and
development of actuators, electric control boxes, controls, and chargers.
This user manual does not address the end-user, but is intended as a source of information for the
manufacturer of the equipment or system only, and it will tell you how to install, use and maintain your LINAK
electronics. It is the responsibility of the manufacturer of the end-use product to provide a User Manual where
relevant safety information from this manual is passed on to the end-user.
We are sure that your LINAK product/system will give you many years of problem-free operation. Before our
products leave the factory they undergo full function and quality testing. Should you nevertheless experience
problems with your LINAK product/system, you are always welcome to contact your local dealer. LINAK
subsidiaries and some distributors situated all over the world have authorised service centres, which are
always ready to help you.
LINAK provides a warranty on all its products. This warranty, however, is subject to correct use in accordance
with the specifications, maintenance being done correctly and any repairs being carried out at a service centre,
which is authorised to repair LINAK products.
Changes in installation and use of LINAK products/systems can affect their operation and durability. The
products are not to be opened by unauthorised personnel.
The User Manual has been written based on our present technical knowledge. We are constantly working on
updating the information and we therefore reserve the right to carry out technical modifications.
LINAK A/S
Page 5

Page 5 of 76
LINAK application policy
The purpose of the application policy is to define areas of responsibilities in relation to applying a LINAK
product defined as hardware, software, technical advice, etc. related to an existing or a new customer
application.
LINAK products as defined above are applicable for a wide range of applications within Medical, Furniture,
Desk, and Industry areas. Yet, LINAK cannot know all the conditions under which LINAK products will be
installed, used, and operated, as each individual application is unique.
The suitability and functionality of the LINAK product and its performance under varying conditions (application,
vibration, load, humidity, temperature, frequency, etc.) can only be verified by testing, and shall ultimately be
the responsibility of the LINAK customer using any LINAK product.
LINAK shall be responsible solely that LINAK products comply with the specifications set out by LINAK and it
shall be the responsibility of the LINAK customer to ensure that the specific LINAK product can be used for the
application in question.
Page 6

Page 6 of 76
Chapter 1
Safety instructions
Please read this safety information carefully:
Be aware of the following three symbols throughout the user manual:
Warning!
Failing to follow these instructions can cause accidents resulting in serious personal injury.
Recommendations
Failing to follow these instructions can result in the actuator suffering damage or being ruined.
Additional information
Usage tips or additional information that is important in connection with the use of the actuator.
Furthermore, ensure that all staff who are to connect, mount, or use the actuator are in possession of the
necessary information and that they have access to this user manual.
Persons who do not have the necessary experience or knowledge of the product/products must not use the
product/products. Besides, persons with reduced physical or mental abilities must not use the product/products,
unless they are under surveillance or they have been thoroughly instructed in the use of the apparatus by a
person who is responsible for the safety of these persons.
Moreover, children must be under surveillance to ensure that they do not play with the product.
Before you start mounting/dismounting, ensure that the following points are observed:
• The actuator is not in operation.
• The actuator is free from loads that could be released during this work.
Before you put the actuator into operation, check the following:
• The actuator is correctly mounted as indicated in the relevant user instructions.
• The equipment can be freely moved over the actuator’s whole working area.
• The actuator is connected to a mains electricity supply/transformer with the correct voltage and
which is
dimensioned and adapted to the actuator in question.
• Ensure that the voltage applied matches to the voltage specified on the actuator label.
• Ensure that the connection bolts can withstand the wear.
• Ensure that the connection bolts are secured safely.
Page 7

Page 7 of 76
During operation, please be aware of the following:
• Listen for unusual sounds and watch out for uneven running. Stop the actuator immediately if anything
unusual is observed.
• Do not sideload the actuator.
• Only use the actuator within the specified working limits.
• Do not step or kick on the actuator.
When the equipment is not in use:
• Switch off the mains supply in order to prevent unintentional operation.
• Check regularly for extraordinary wear.
Classification
The equipment is not suitable for use in the presence of a flammable anaesthetic mixture with air or with
oxygen or nitrous oxide.
Warnings
• Do not sideload the actuator.
• When mounting the actuator in the application ensure that the bolts can withstand the wear and that
they are secured safely.
• If irregularities are observed, the actuator must be replaced.
• For actuators with a stroke length below 50mm, the extended position of the mechanical endstop will
always be at 50mm. That means, if an actuator has a stroke of 20mm and the endstop switch in outwards
direction fails, the actuator will travel additional 30mm before reaching mechanical endstop.
Recommendations
• Do not place load on the actuator housing and do prevent impact or blows, or any other form of stress to
the housing.
• Ensure that the cable cover is mounted correctly. Use 1.5Nm torque.
• Ensure that the duty cycle and the usage temperatures for LA25 actuators are respected.
• Ensure that the cable cannot be squeezed, pulled or subjected to any other stress.
• Furthermore, it will be good practice to ensure that the actuator is fully retracted in the “normal” position.
The reason is that there will be a vacuum inside the actuator if it is extended which over time can lead to
water entering the actuator.
• If the actuator (without integrated controller) is mounted in an application where a mechanical stop
prevents the endstop switches in the actuator from being activated, the actuator must be equipped with
an electrical safety device (current monitoring) or external limit switch.
Page 8

Page 8 of 76
The IECEx/ATEX certified LA25 (optional) is designed for installation in dust filled atmospheres such as grain
handling facilities, cement plants, saw mills or other dusty surroundings. Please note that the IECEx/ATEX
approval is only for dust, and NOT for gas.
The IECEx/ATEX versions are suitable for applications in Group IIIC, Category 2D. Zone 21 and 22.
IECEx/ATEX
Operation of the device is only valid if:
• The product is used under the conditions described in the installation - and operation instruction
• Ambient operating temperature -25°C to +65°C depending on duty cycle
• Atmospheric conditions: Pressure 80 kPa (0.8 bar) to 110 kPa (1.1 bar); and air with normal oxygen content,
typically 21% v/v
• Since the signal and power cables are not UV resistant they need to be shielded against UV light, e.g. daylight
or light from luminaries
• The connection between the actuator and the rest of the machine/device shall be conductive,
and furthermore the application shall be grounded in order to remove any Electro Static Discharge. This counts
for both of the actuator’s fixation points (Back Fixture and Piston Rod Eye)
• Safety and operation instructions are accessible and followed
• Not to be opened in areas with dust, and never by unauthorized personnel
• The production of IECEx/ATEX actuators require quality management systems and auditing.
Therefore, only LINAK A/S is allowed to produce, modify or repair actuators in order to sustain the approval.
No changes are to be made on the actuator after delivery
This manual is part of the equipment. The manufacturer keeps the right to modify specifications without
advanced notice. Keep this manual for later use.
*
Warnings
If the following is not complied with, the IECEx/ATEX certification will not be valid:
• Actuator specifications must be complied with
• If the actuator has no built-in current cut-off, one must be mounted
• Only IECEx/ATEX approved cables are to be used *
• The power supply/signal cables for the actuator must be terminated in a safe location or alternatively by use of an
Ex terminal box certified for special conditions for safe use
LA25 IECEx/ATEX
cable item no.
Length (mm) outside
the actuator
0147006 - 850 790
0147006 - 1600 1540
0147006 - 5100 5040
Page 9

Page 9 of 76
General indication of risk:
Installation of the device shall be performed by trained staff only, familiar with the safety requirements and risks.
Check all relevant safety regulations and technical indications for the specific installation place.
Prevent failures and protect persons against injuries and the device against damage.
The person responsible for the system must secure that:
• Safety and operation instructions are accessible and followed
• Local safety regulations and standards are obeyed
• Performance data and installation specifications are regarded
• Safety devices are installed and recommended maintenance is performed
• National regulations for disposal of electrical equipment are obeyed
Maintenance and repair:
• Repairs on the device must be carried out by LINAK authorised persons only
• Only perform mounting described in this manual
During maintenance regard all safety regulations and internal operation instructions.
IECEx/ATEX
Page 10

Page 10 of 76
Right WrongWrong Wrong
Mounting guidelines
LINAK® linear actuators are quickly and easily mounted by slipping pins through the holes on each end of the
units and into brackets on the machine frame and the load.
Chapter 2
The mounting pins must be parallel to each other as
shown in Figure 1. Pins, which are not parallel to each
other, may cause the actuator to bend and be damaged.
The load should act along the stroke axis of the actuator
as off-centre loads may cause bending and lead to
premature failure. See Figure 2.
Make sure the mounting pins are supported in both
ends. Failure to do so could shorten the life of the
actuator. Also, avoid applying a skew load on the
actuator.
The actuator can rotate around the pivot point in the front and rear end. If this is the case it is of high
importance that the actuator is able to move freely over the full stroke length, both during the development
and daily operation. Please pay special attention to the area around the housing where parts can be trapped
and cause damage to the application and actuator.
In applications with high dynamic forces LINAK recommends not to use the fully extended or retracted position
over longer time, as this can damage the endstop system permanently.
Figure 2
Figure 1
Page 11

Page 11 of 76
Mounting guidelines
030618/DS
Instruktion vedr. uddrejning af inderrør – LA27 + LA27C
Til salesbackup, brugsanvisning og datablad.
Ved montage og ibrugtagning, er det ikke tilladt at dreje unødvendigt mange gange på
stempelstangsrøret. Hvis øjet ikke er positioneret korrekt, er det tilladt først at skrue
røret i bund (1), og derefter skrue det maksimalt ½ omgang ud igen (2).
• The mounting pins must have the correct dimension
• The bolts and nuts must be made of a high quality steel grade (e.g. 10.8).
No thread on the bolt inside the back fixture or the piston rod eye
• Bolts and nuts must be protected so there is no risk for them to fall out
• Do not use a torque that is too high when mounting the bolts for the back fixture or the piston rod
eye. This will stress the fixtures
Please note:
The piston rod eye is only allowed to turn 0-90 degrees.
Instruction concerning the turning of the piston rod eye and inner tube:
• When mounting and taking into use, it is not permitted to make excessive turns of the piston rod
eye. In cases where the eye is not positioned correctly, it is permitted to first screw the eye down
to its bottom position, at a maximum torque of 2Nm (1), and thereafter a maximum 90 degrees
turn outwards again (2).
• As the piston rod eye can turn freely, it is important to ensure that the eye cannot rotate if
the actuator is used in a pull application. If this happens, the actuator will be pulled apart and
destroyed.
Warning!
If the actuator is used for pull in an application where personal injury can occur, the
following is valid:
It is the application manufacturer’s responsibility to incorporate a suitable safety arrangement, which
will prevent personal injury from occurring, if the actuator should fail
Warning!
LINAK’s actuators are not designed for use within the following fields:
• Offshore installations • Nuclear power generation
• Aeroplanes and other aircraft
Page 12

Page 12 of 76
Mounting of cables
• When changing the cables on a LINAK actuator, it is important that this is done carefully, in order to
protect the plugs and pins. Before the new cable is mounted, we recommend that the socket is
greased with vaseline, to keep the high IP protection and ensure an easy mounting. Please be sure
that the plug is in the right location and fully pressed in before the cable lid is mounted.
Note that the cable should not be used for carrying the actuator.
• We recommend to take some precaution and design the wire connection in a way, where the cable
end is kept inside a closed, protected area to guarantee the high IP protection.
1. Unscrew the cover 2. Remove the cover 3. Plug in the cable gently
without using any tools
Removing cables
4. Screw the cover back onto the actuator
The torque of the cover
screw is approx. 1.5 Nm
5. Use a screwdriver to pull up the
cable
Page 13

Page 13 of 76
Electrical installation
Recommended fuse for actuators without integrated controller
Type Spindle
Pitch
(mm)
Thrust
max. Push/
Pull
(N)
Typical Amp.
at full load
(A)
24V - 12V
Recommended
fuse
24V - 12V
25030xxxxxxxxA... 3 2500 - 3.8 - 10A
25060xxxxxxxxA... 6 1500 - 3.8 - 10A
25090xxxxxxxxA... 9 1200 - 4.0 - 10A
25120xxxxxxxxA... 12 900 - 3.8 - 10A
25200xxxxxxxxA... 20 600 - 4.0 - 10A
25030xxxxxxxxB... 3 2500 1.9 - 6A -
25060xxxxxxxxB... 6 1500 1.9 - 6A -
25090xxxxxxxxB... 9 1200 2.0 - 6A -
25120xxxxxxxxB... 12 900 1.9 - 6A -
25200xxxxxxxxB... 20 600 2.0 - 6A -
• To ensure maximum self-locking ability, please be sure that the motor is shorted when stopped.
Actuators with integrated controller provide this feature, as long as the actuator is powered.
• When using soft stop on a DC-motor, a short peak of higher voltage will be sent back towards
the power supply. It is important when selecting the power supply that it does not turn off the
output, when this backwards load dump occurs.
The power supply for actuators without integrated controller must be monitored externally and cut
off in case of current overload.
Page 14

Page 14 of 76
Fig. 1 : 25xxxxxxxx000x0x=xxxxx00xxxxxx
Input/Output Specification Comments
Description Permanent magnetic DC motor.
See connection diagram,
fig. 1 above
Brown
12-24VDC (+/-)
12V ± 20%
24V ± 10%
Under normal conditions:
12V, max. 5A depending on load
24V, max. 2.5A depending on load
To extend actuator:
Connect Brown to positive
To retract actuator:
Connect Brown to negative
Blue To extend actuator:
Connect Blue to negative
To retract actuator:
Connect Blue to positive
Red Not to be connected
Black Not to be connected
Green Not to be connected
Yellow Not to be connected
Violet Not to be connected
White Not to be connected
BROWN
BLUE
Actuator without feedback
Connection diagram:
I/O specifications:
DEUTSCH
Standard connector front view
AMP
2P2P
22
11
Page 15

Page 15 of 76
*YELLOW/GREEN: Endstop signals out are NOT potential free!
If you wish to use the endstop signals, you will have to keep power on the brown, blue, red and black wires,
otherwise the signal will be lost.
AMP
6P
2
1
4
5
6
3
DEUTSCH
8P
2
1
4
7
8
3
Standard connector front view
Fig. 2 : 25xxxxxxxx000x0x=xxxxx10xxxxxx
YELLOW*
GREEN*
IN
OUT
BROWN
BLUE
RED
BLACK
+
-
Actuator with endstop signal output
Connection diagram:
Page 16

Page 16 of 76
Input/Output Specification Comments
Description The actuator can be equipped with elec-
tronically controlled endstop signals out.
See connection diagram,
fig. 2, page 16
Brown
12-24VDC (+/-)
12V ± 20%
24V ± 10%
Under normal conditions:
12V, max. 5A depending on load
24V, max. 2.5A depending on load
To extend actuator:
Connect Brown to positive
To retract actuator:
Connect Brown to negative
Blue To extend actuator:
Connect Blue to negative
To retract actuator:
Connect Blue to positive
Red Signal power supply (+)
12-24VDC
Current consumption:
Max. 40mA, also when the actuator is
not running
Black Signal power supply GND (-)
Green Endstop signal out Output voltage min. V
IN
- 2V
Source current max. 100mA
NOT potential free
Yellow Endstop signal in
Violet Not to be connected
White Not to be connected
IN
OUT
Actuator with endstop signal output
I/O specifications:
Page 17

Page 17 of 76
Fig. 3 : 25xxxxxxxx0K0x0x=xxxxx00xxxxxx
BROWN
BLUE
RED
VIOLET
BLACK
+
-
Actuator with relative positioning - Single Hall
Connection diagram:
AMP DEUTSCH
5P
2
1
4
5
3
6P
2
1
4
6
3
Standard connector front view
Page 18

Page 18 of 76
Fig. 3.1
Micro Processor
Input Single Hall output
Hall B
Hall A
Input/Output Specification Comments
Description The actuator can be equipped with Single
Hall that gives a relative positioning
feedback signal when the actuator moves.
See connection diagram,
fig. 3, page 18
Brown
12-24VDC (+/-)
12V ± 20%
24V ± 10%
Under normal conditions:
12V, max. 5A depending on load
24V, max. 2.5A depending on load
To extend actuator:
Connect Brown to positive
To retract actuator:
Connect Brown to negative
Blue To extend actuator:
Connect Blue to negative
To retract actuator:
Connect Blue to positive
Red Signal power supply (+)
12-24VDC
Current consumption:
Max. 40 mA, also when the actuator is
not running
Black Signal power supply GND (-)
Green Not to be connected
Yellow Not to be connected
Violet Single Hall output (PNP)
Movement per single Hall pulse:
LA25030 Actuator = 0.25 mm per pulse
LA25060 Actuator = 0.5 mm per pulse
LA25090 Actuator = 0.75 mm per pulse
LA25120 Actuator = 1.0 mm per pulse
LA25200 Actuator = 1.7 mm per pulse
Frequency:
Frequency is 10-20Hz on Single Hall output
depending on load.
Pulse ON time is minimum 8ms.OFF time
between two ON pulses is minimum 8ms.
Overvoltage on the motor can result in
shorter pulses.
Output voltage min. V
IN
- 2V
Max. current output: 12mA
Max. 680 nF
N.B. For more precise measurements,
please contact LINAK A/S.
Low frequency with a high load.Higher
frequency with no load.
Diagram of Single Hall:
White Not to be connected
Actuator with relative positioning - Single Hall
I/O specifications:
Page 19

Page 19 of 76
*YELLOW/GREEN: Endstop signals out are NOT potential free! (See I/O Specifications, page 17)
If you wish to use the endstop signals, you will have to keep power on the brown, blue, red and black wires,
otherwise the signal will be lost.
Fig. 4 : 25xxxxxxxx0K0x0x=xxxxx10xxxxxx
BROWN
BLUE
YELLOW*
GREEN*
IN
OUT
RED
VIOLET
BLACK
+
-
Actuator with endstop signals and relative positioning - Single Hall
Connection diagram:
DEUTSCH
8P
2
1
4
7
8
6
3
Standard connector front view
Page 20

Page 20 of 76
Input/Output Specification Comments
Description The actuator can be equipped with Single
Hall that gives a relative positioning feedback signal when the actuator moves.
See connection diagram,
fig. 4, page 20
Brown
12-24VDC (+/-)
12V ± 20%
24V ± 10%
Under normal conditions:
12V, max. 5A depending on load
24V, max. 2.5A depending on load
To extend actuator:
Connect Brown to positive
To retract actuator:
Connect Brown to negative
Blue To extend actuator:
Connect Blue to negative
To retract actuator:
Connect Blue to positive
Red Signal power supply (+)
12-24VDC
Current consumption:
Max. 40mA, also when the actuator is
not running
Black Signal power supply GND (-)
Green Endstop signal out Output voltage min. V
IN
- 2V
Source current max. 100mA
NOT potential free
Yellow Endstop signal in
Violet Single Hall output (PNP)
Movement per single Hall pulse:
LA25030 Actuator = 0.25 mm per pulse
LA25060 Actuator = 0.5 mm per pulse
LA25090 Actuator = 0.75 mm per pulse
LA25120 Actuator = 1.0 mm per pulse
LA25200 Actuator = 1.7 mm per pulse
Frequency:
Frequency is 10-20Hz on Single Hall output
depending on load.
Pulse ON time is minimum 8ms.OFF time
between two ON pulses is minimum 8ms.
Overvoltage on the motor can result in
shorter pulses.
Output voltage min. V
IN
- 2V
Max. current output: 12mA
Max. 680nF
N.B. For more precise measurements,
please contact
LINAK A/S.
Low frequency with a high load.Higher
frequency with no load.
Diagram of Single Hall:
White Not to be connected
Actuator with endstop signals and relative positioning - Single Hall
I/O specifications:
Fig. 4.1
Micro Processor
Input Single Hall output
Hall B
Hall A
Page 21

Page 21 of 76
Fig. 5 : 25xxxxxxxx0A0x0x=xxxxx0xxxxxxx
BROWN
BLUE
VIOLET
RED
+
BLACK
-
Actuator with absolute positioning - Analogue feedback
Connection diagram:
AMP DEUTSCH
5P
2
1
4
5
3
6P
2
1
4
6
3
Standard connector front view
Page 22

Page 22 of 76
Actuator with absolute positioning - Analogue feedback
I/O specifications:
Input/Output Specification Comments
Description The actuator can be equipped with elec-
tronic circuit that gives an analogue feedback signal when the actuator moves.
See connection diagram,
fig. 5, page 22
Brown
12 - 24 V DC (+/-)
12V ± 20%
24V ± 10%
Under normal conditions:
12V, max. 5A depending on load
24V, max. 2.5A depending on load
To extend actuator:
Connect Brown to positive
To retract actuator:
Connect Brown to negative
Blue To extend actuator:
Connect Blue to negative
To retract actuator:
Connect Blue to positive
Red Signal power supply (+)
12 - 24 V DC
Current consumption:
Max. 60 mA, also when the actuator is
not running
Black Signal power supply GND (-)
Green Not to be connected
Yellow Not to be connected
Violet Analogue feedback
0-10V (Feedback level 1)
0.5-4.5V (Feedback level 2)
Tolerances +/- 0.2 V
Max. current output: 1 mA
Ripple max. 200 mV
Transaction delay max. 20 ms
Linear feedback 0.5%
Source current max. 1 mA
4-20mA (Feedback level 3)
Special (Feedback level 9)
Tolerances +/- 0.2 mA
Transaction delay 20ms
Linear feedback 0.5%
Output: Source
Serial resistance:
12V max 300 ohm
24V max. 900 ohm
For all analogue feedbacks it is recommendable to have the actuator to activate its
limit switches on a regular basis, to ensure more precise positioning
White Not to be connected
Page 23

Page 23 of 76
*YELLOW/GREEN: Endstop signals out are NOT potential free! (See I/O Specifications, page 17)
If you wish to use the endstop signals, you will have to keep power on the brown, blue, red and black wires,
otherwise the signal will be lost.
Actuator with endstop signals and absolute positioning Analogue feedback
Connection diagram:
BROWN
BLUE
Signal
YELLOW*
GREEN*
IN
OUT
RED
VIOLET
BLACK
+
-
Fig. 6 : 25xxxxxxxx0A0x0x=xxxxx1xxxxxxx
DEUTSCH
8P
2
1
4
7
8
6
3
Standard connector front view
Page 24
Page 24 of 76
Input/Output Specification Comments
Description The actuator can be equipped with elec-
tronic circuit that gives an analogue feedback signal when the actuator moves.
See connection diagram,
fig. 6, page 24
Brown
12-24VDC (+/-)
12V ± 20%
24V ± 10%
Under normal conditions:
12V, max. 5A depending on load
24V, max. 2.5A depending on load
To extend actuator:
Connect Brown to positive
To retract actuator:
Connect Brown to negative
Blue To extend actuator:
Connect Blue to negative
To retract actuator:
Connect Blue to positive
Red Signal power supply (+)
12-24VDC
Current consumption:
Max. 60mA, also when the actuator is
not running
Black Signal power supply GND (-)
Green Endstop signal out Output voltage min. V
IN
- 2V
Source current max. 100mA
NOT potential free
Yellow Endstop signal in
Violet Analogue feedback
0-10V (Feedback level 1)
0.5-4.5V (Feedback level 2)
Tolerances +/- 0.2V
Max. current output: 1mA
Ripple max. 200mV
Transaction delay max. 20ms
Linear feedback 0.5%
Source current max. 1mA
4-20mA (Feedback level 3)
Special (Feedback level 9)
Tolerances +/- 0.2mA
Transaction delay 20ms
Linear feedback 0.5%
Output: Source
Serial resistance:
12V max 300 ohm
24V max. 900 ohm
For all analogue feedbacks it is recommendable to have the actuator to activate its
limit switches on a regular basis, to ensure more precise positioning
White Not to be connected
Actuator with endstop signals and absolute positioning Analogue feedback
I/O specifications:
Page 25
Page 25 of 76
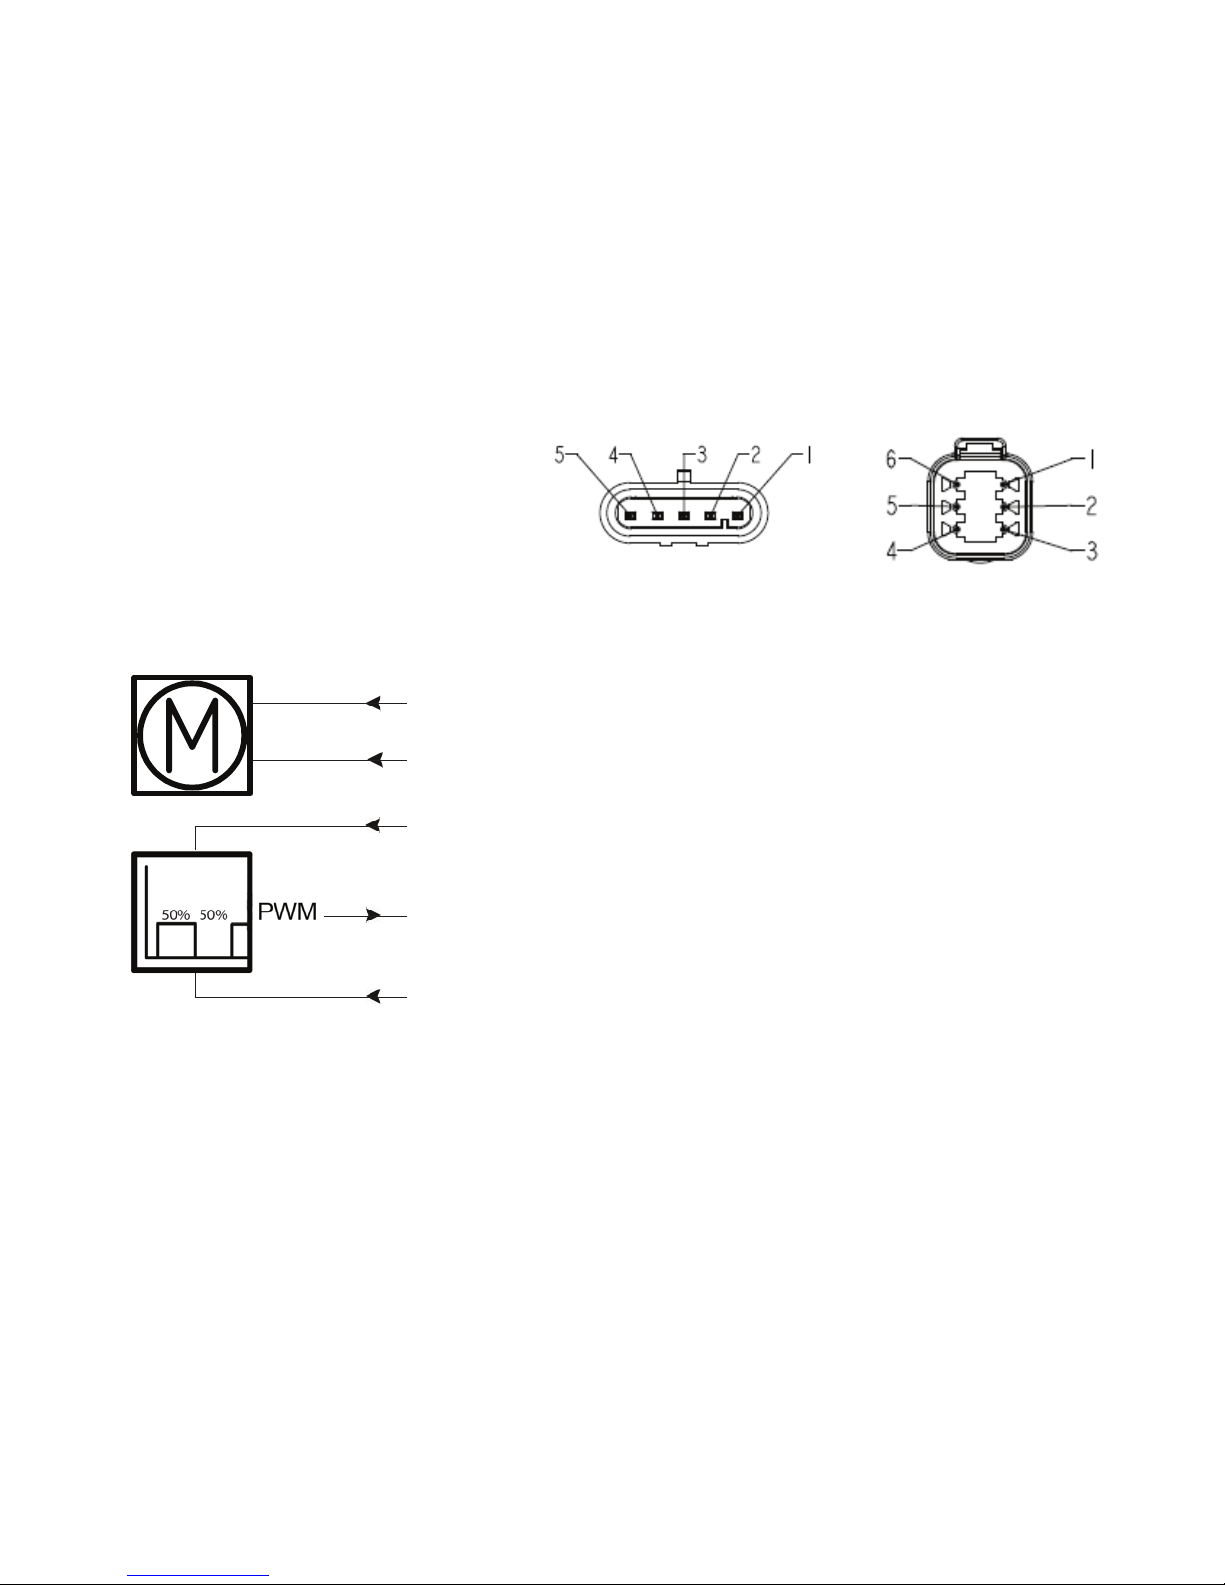
Fig. 7 : 25xxxxxxxx0F0x0x=xxxxx0xxxxxxx
BROWN
BLUE
RED
VIOLET
+
BLACK
-
Actuator with absolute positioning - PWM
Connection diagram:
DEUTSCH
6P
2
1
4
6
3
AMP
5P
2
1
4
5
3
Standard connector front view
Page 26
Page 26 of 76
Input/Output Specification Comments
Description The actuator can be equipped with
electronic circuit that gives an analogue
feedback signal when the actuator moves.
See connection diagram,
fig. 7, page 26
Brown
12-24VDC (+/-)
12V ± 20%
24V ± 10%
Under normal conditions:
12V, max. 5A depending on load
24V, max. 2.5A depending on load
To extend actuator:
Connect Brown to positive
To retract actuator:
Connect Brown to negative
Blue To extend actuator:
Connect Blue to negative
To retract actuator:
Connect Blue to positive
Red Signal power supply (+)
12-24VDC
Current consumption:
Max. 40 mA, also when the actuator is
not running
Black Signal power supply GND (-)
Green Not to be connected
Yellow Not to be connected
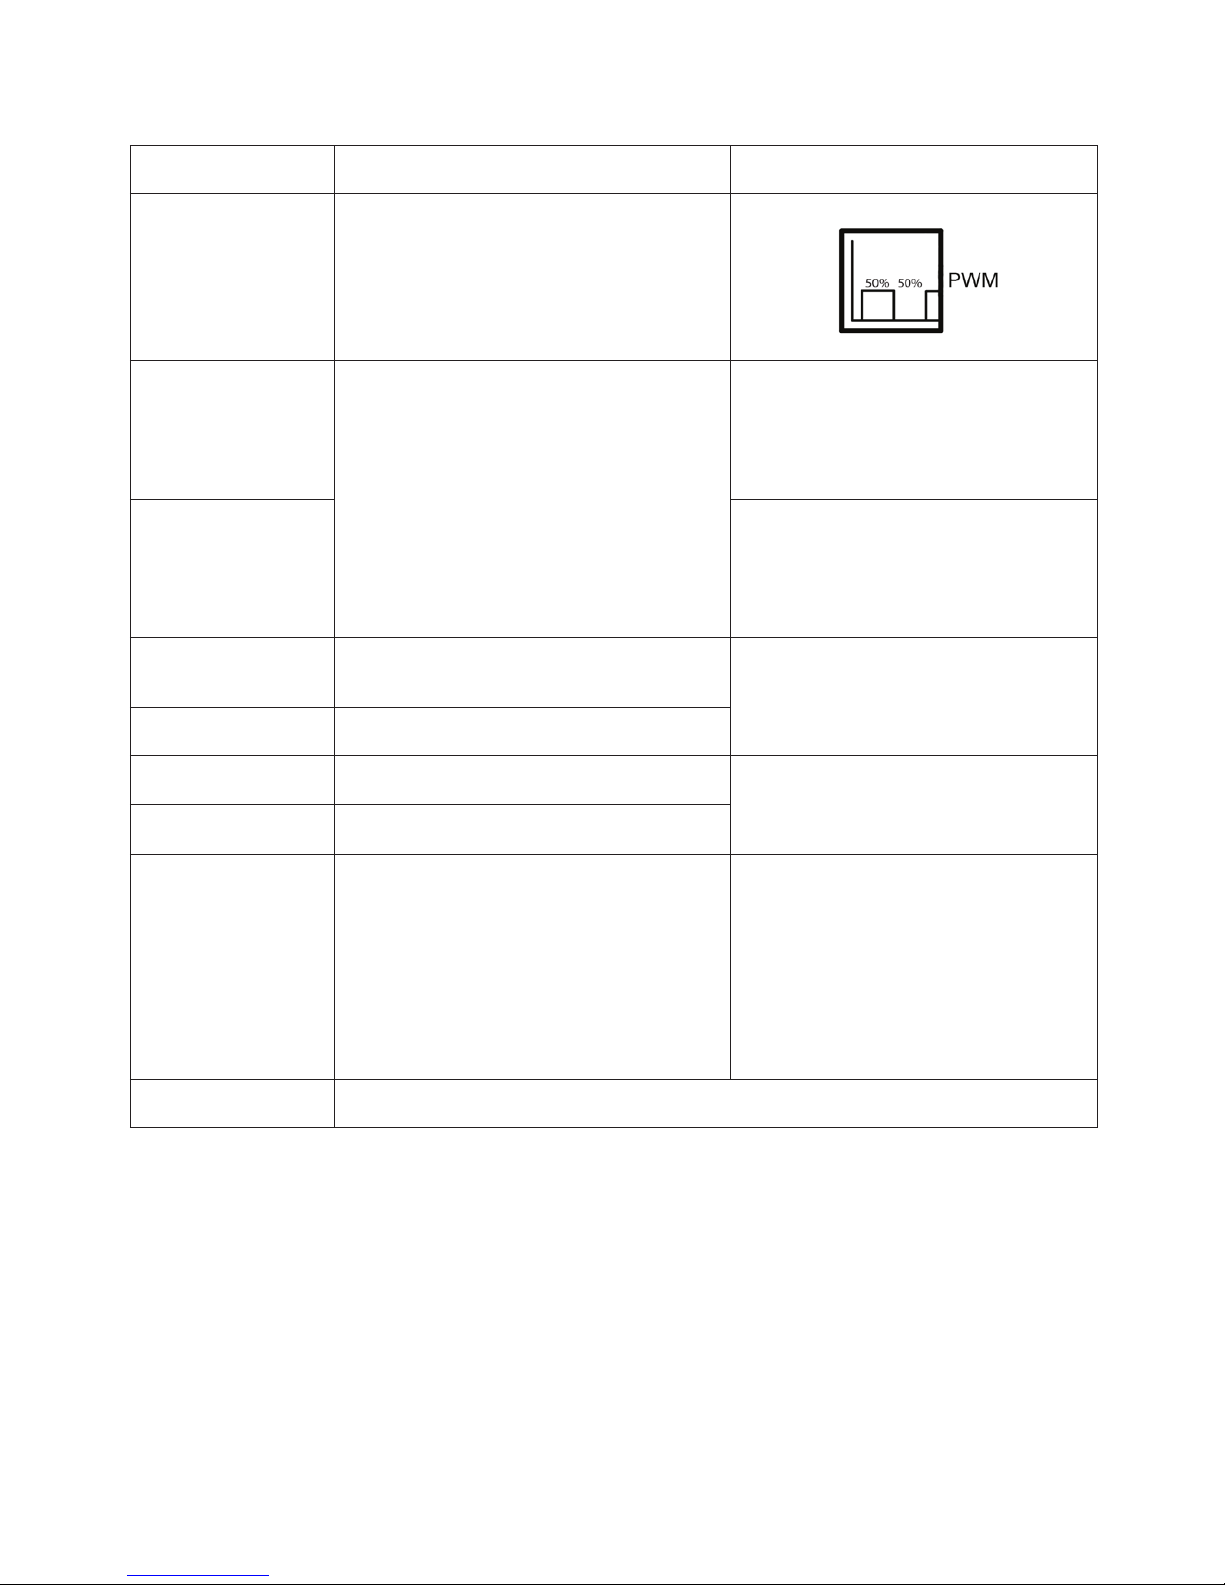
Violet Digital output feedback
10-90% (Feedback level 4)
20-80% (Feedback level 5)
Special (Feedback level 9)
Output voltage min. V
IN
- 2V
Tolerances +/- 2%
Max. current output: 12mA
It is recommendable to have the actuator to activate its limit switches on a
regular basis, to ensure more precise
positioning
White Not to be connected
I/O specifications:
Actuator with absolute positioning - PWM
Page 27
Page 27 of 76
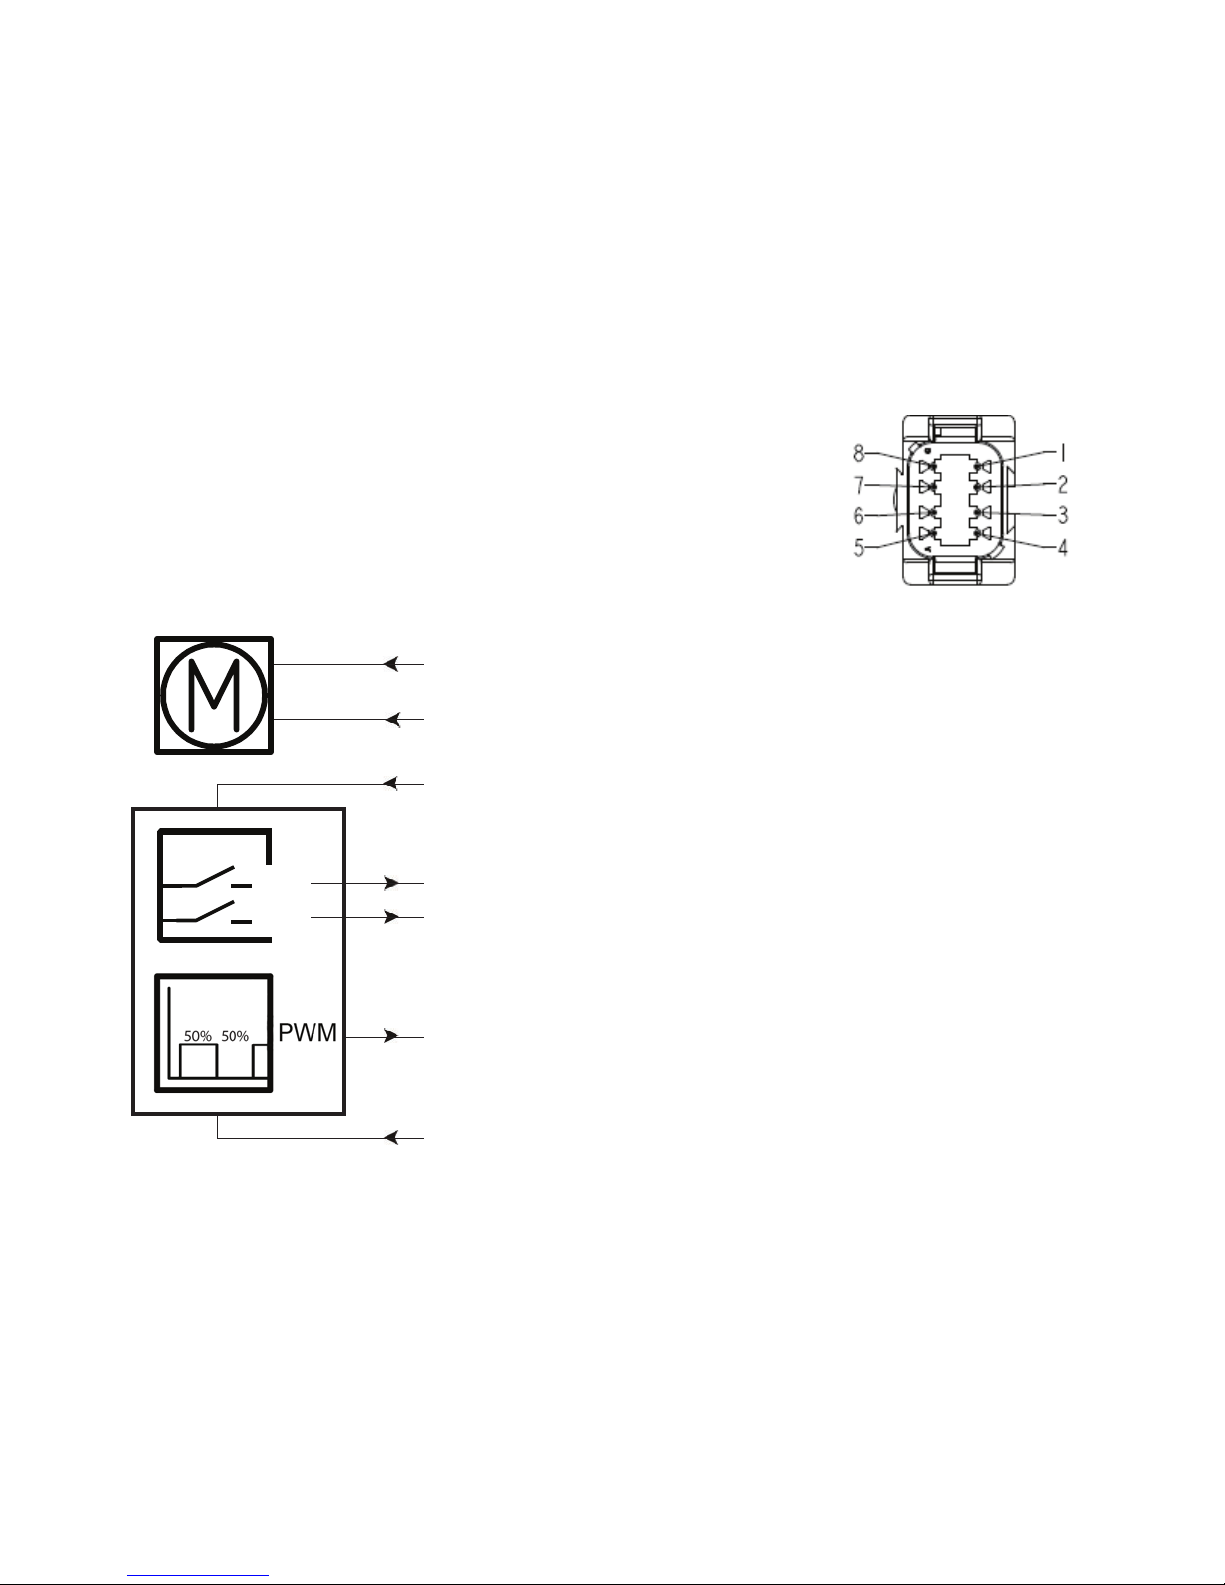
Fig. 8 : 25xxxxxxxx0F0x0x=xxxxx1xxxxxxx
*YELLOW/GREEN: Endstop signals out are NOT potential free! (See I/O Specifications, page 17)
If you wish to use the endstop signals, you will have to keep power on the brown, blue, red and black wires,
otherwise the signal will be lost.
BROWN
BLUE
YELLOW*
GREEN*
IN
OUT
RED
VIOLET
+
BLACK
-
Actuator with endstop signals and absolute positioning - PWM
Connection diagram:
DEUTSCH
8P
2
1
4
7
8
6
3
Standard connector front view
Page 28
Page 28 of 76
Input/Output Specification Comments
Description The actuator can be equipped with elec-
tronic circuit that gives an analogue feedback signal when the actuator moves.
See connection diagram,
fig. 8, page 28
Brown
12-24VDC (+/-)
12V ± 20%
24V ± 10%
Under normal conditions:
12V, max. 5A depending on load
24V, max. 2.5A depending on load
To extend actuator:
Connect Brown to positive
To retract actuator:
Connect Brown to negative
Blue To extend actuator:
Connect Blue to negative
To retract actuator:
Connect Blue to positive
Red Signal power supply (+)
12-24VDC
Current consumption:
Max. 40mA, also when the actuator is
not running
Black Signal power supply GND (-)
Green Endstop signal out Output voltage min. V
IN
- 2V
Source current max. 100mA
NOT potential free
Yellow Endstop signal in
Violet Digital output feedback
10-90% (Feedback level 4)
20-80% (Feedback level 5)
Special (Feedback level 9)
Output voltage min. V
IN
- 2V
Tolerances +/- 2%
Max. current output: 12mA
It is recommendable to have the
actuator to activate its limit switches
on a regular basis, to ensure more
precise positioning
White Not to be connected
I/O specifications:
Actuator with endstop signals and absolute positioning - PWM
Page 29
Page 29 of 76
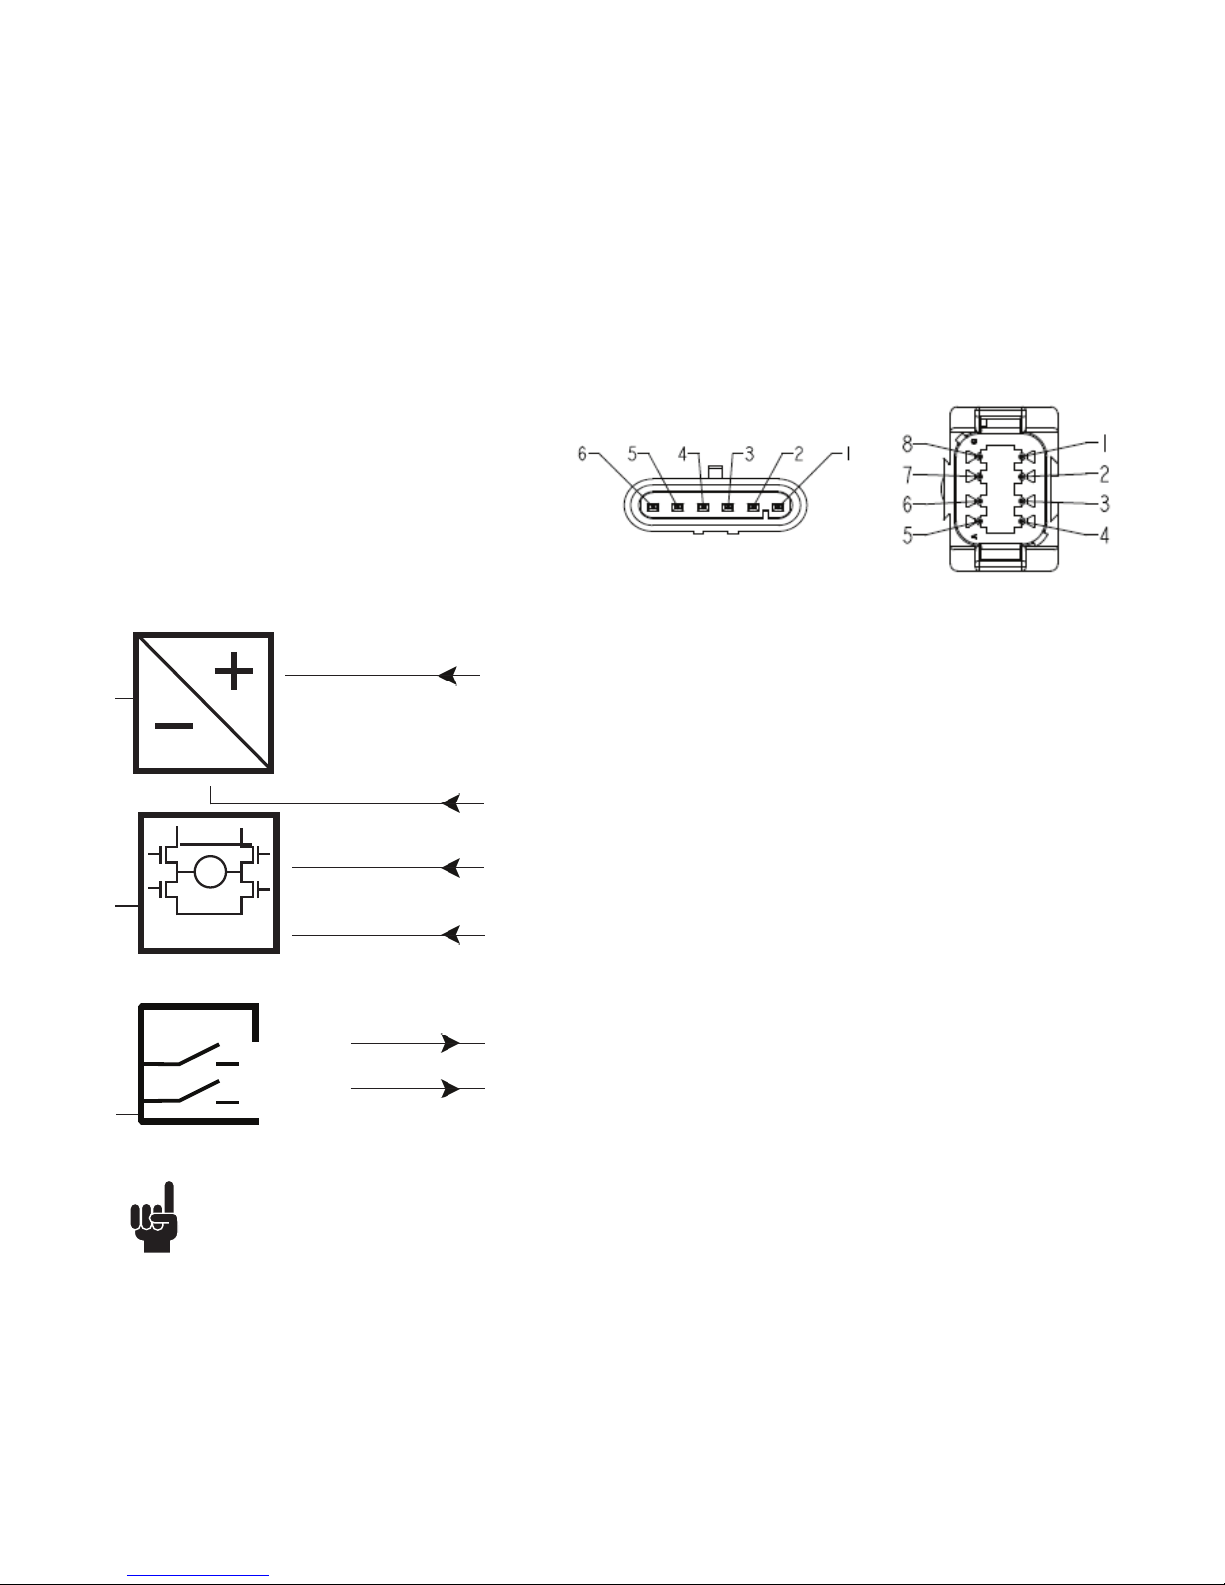
Actuator with IC Basic
Connection diagram:
Fig. 9 : 25xxxxxxxxxx3x1x=xxxxx18xxxxxx
BROWN
BLUE
YELLOW
GREEN
BLACK
12/24V DC
RED
INWARDS
OUTWARDS
M
H-Bridge
IN
OUT
DEUTSCH
8P
2
1
3
4
7
8
AMP
6P
2
1
3
4
5
6
Standard connector front view
Please be aware that if the power supply is not properly connected, you might damage the actuator!
Page 30
Page 30 of 76
Input/Output Specification Comments
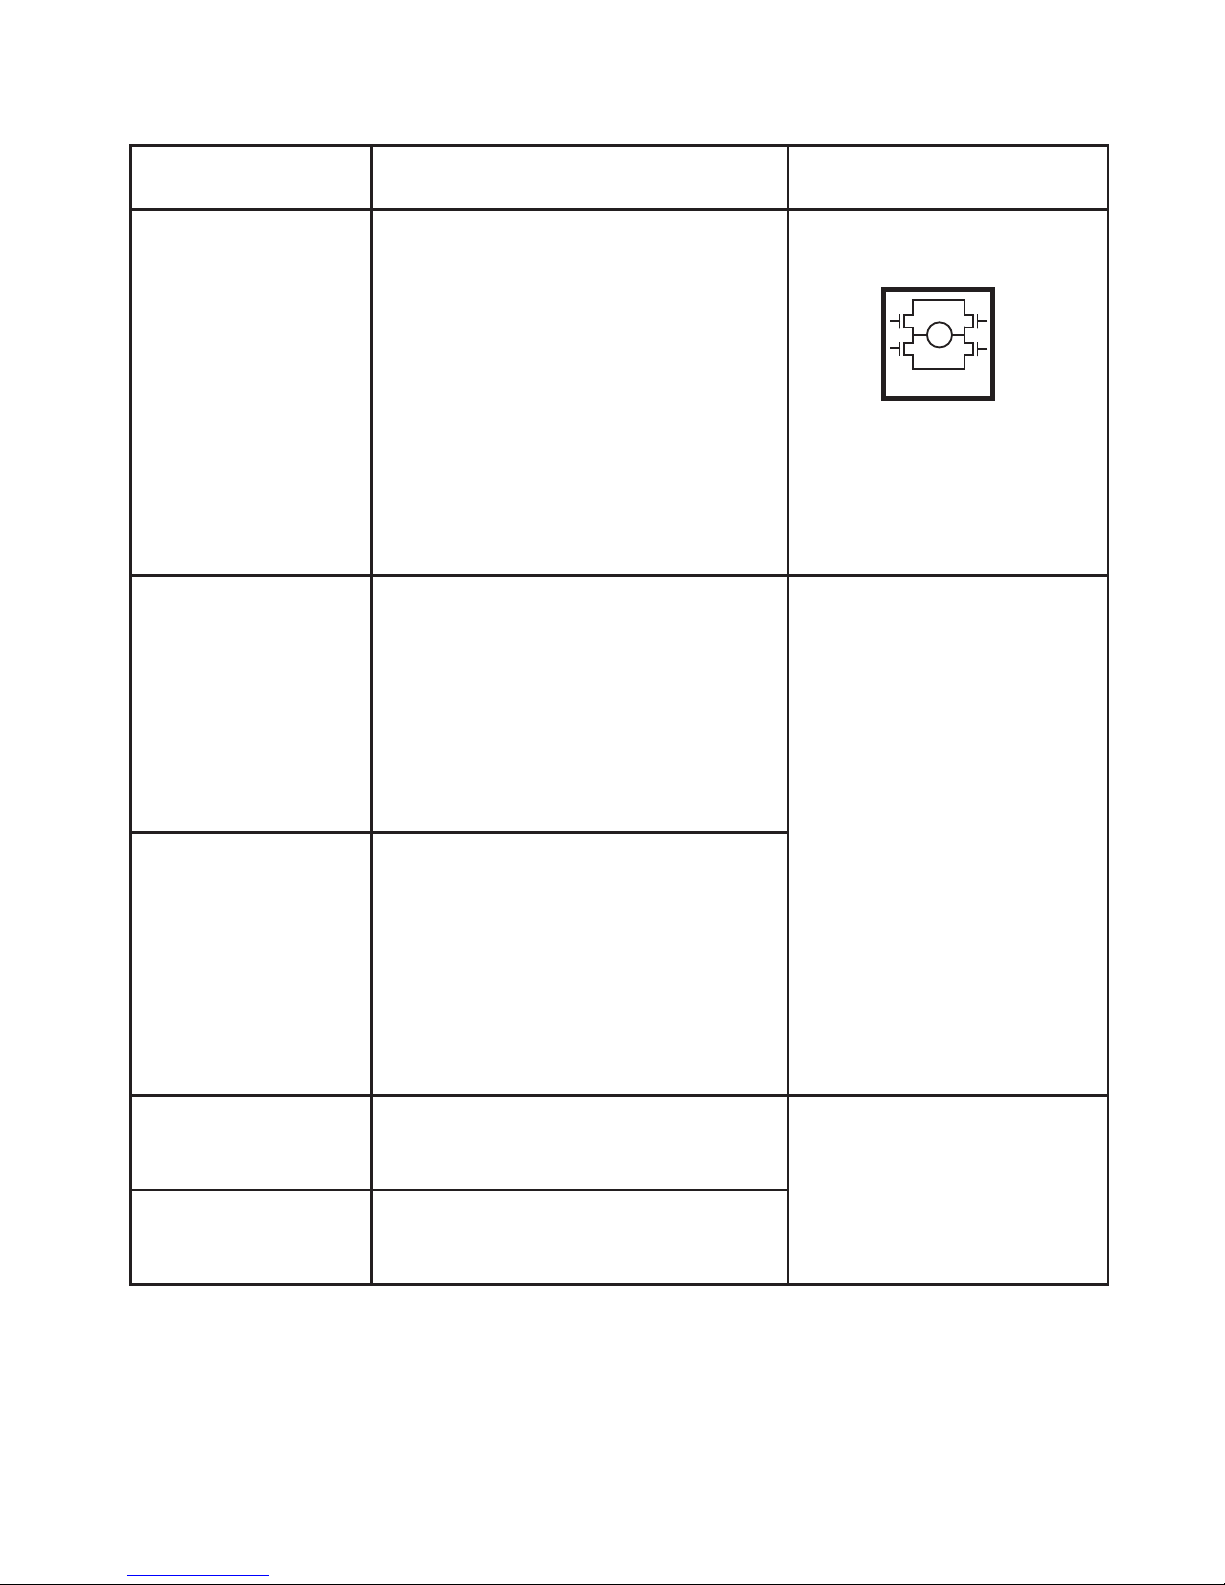
Description Easy to use interface with integrated power
electronics (H-bridge).
The actuator can also be equipped with
electronic circuit that gives an absolute or
relative feedback signal.
IC Advanced also provides a wide range of
possibilities for customisation.
The version with “IC option” cannot be
operated with PWM (power supply).
See connection diagram,
fig. 10, page 39
Brown 12-24VDC + (VCC)
Connect Brown to positive
12V ± 20%
24V ± 10%
12V, current limit 8A
24V, current limit 5A
Note: Do not change the power
supply polarity on the brown and
blue wires!
Power supply GND (-) is electrically connected to the housing
Current limit levels can be
adjusted through BusLink
If the temperature drops below
-10°C, all current limits will automatically increase to 9A for 12V,
and 6A for 24V
Blue 12-24VDC - (GND)
Connect Blue to negative
12V ± 20%
24V ± 10%
12V, current limit 8A
24V, current limit 5A
Red Extends the actuator On/off voltages:
> 67% of V
IN
= ON
< 33% of V
IN
= OFF
Input current: 10mA
Black Retracts the actuator
M
H-Bridge
Actuator with IC Basic
I/O specifications:
Page 31
Page 31 of 76
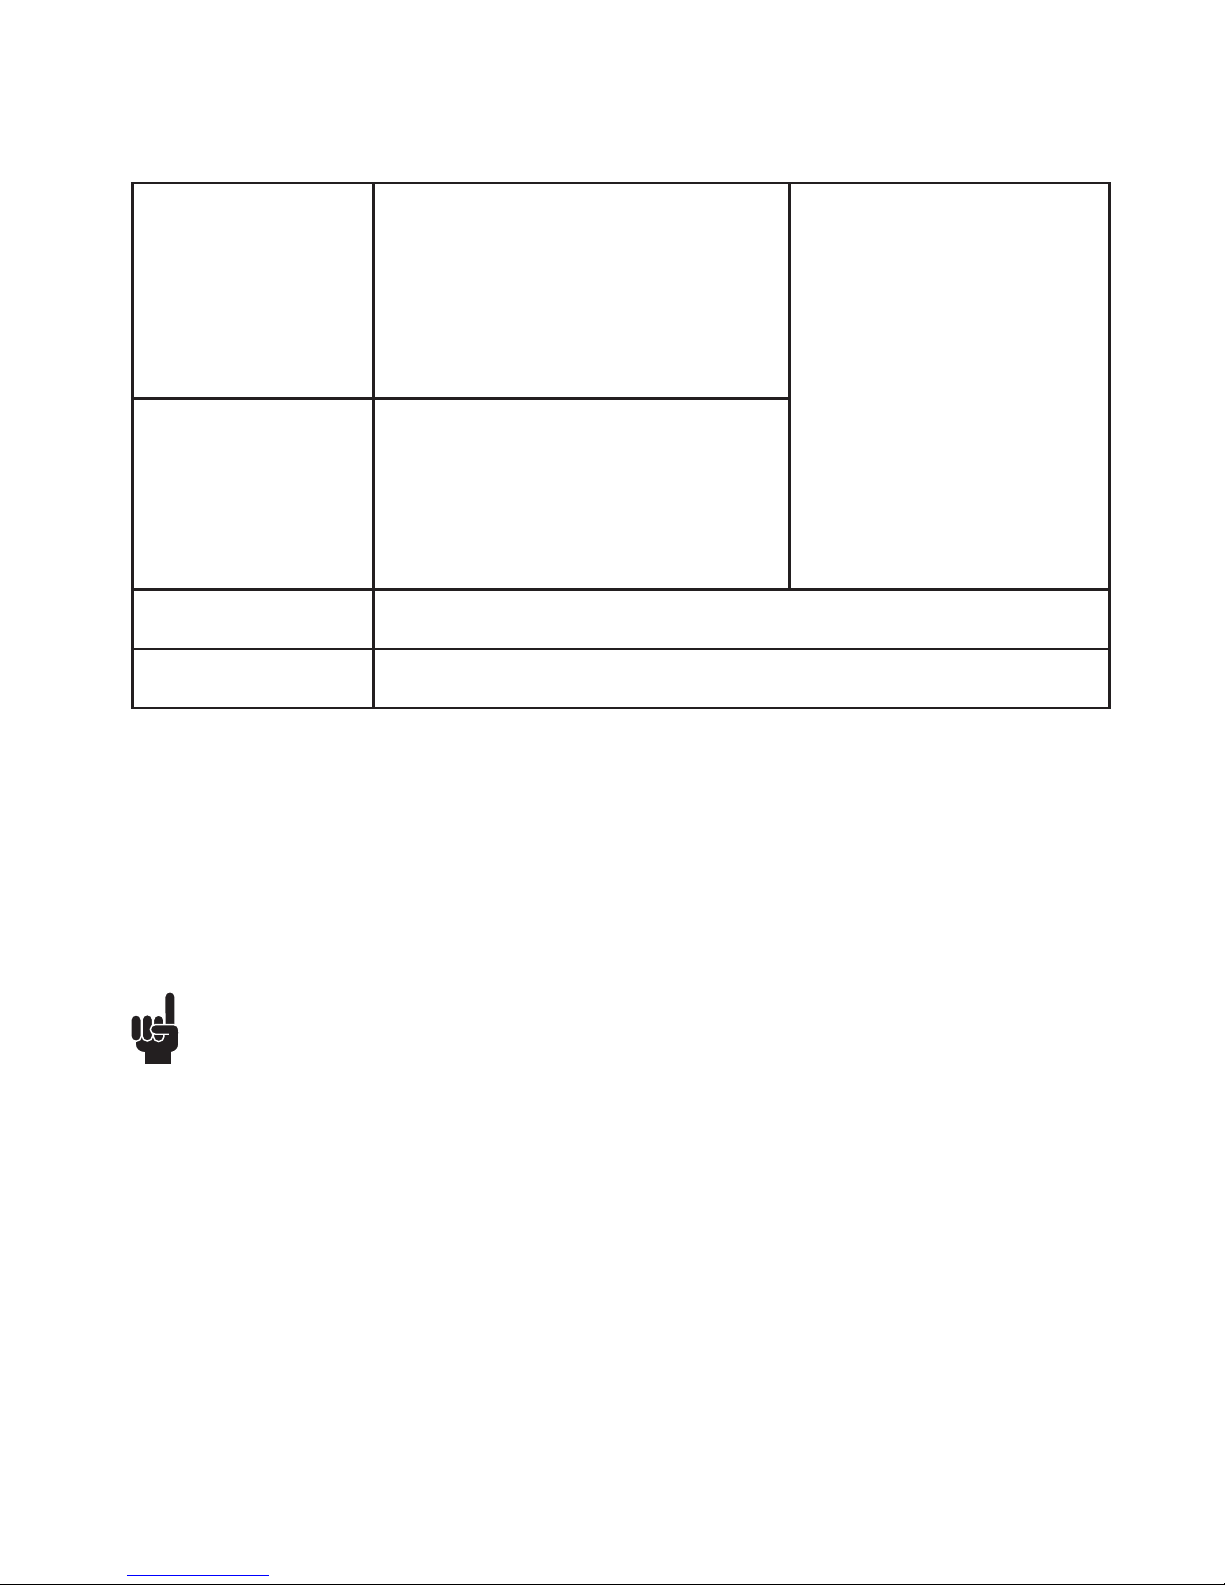
Green Endstop signal out Output voltage min. V
IN
- 2V
Source current max. 100mA
Endstop signals are NOT potential free. Endstop signals can be
configured with BusLink software
according to any position needed
When configuring virtual endstop,
it is not necessary to choose the
position feedback
EOS and virtual endstop will work
even when feedback is not chosen
Yellow Endstop signal in
Violet Not to be connected
White Not to be connected
Actuator with IC Basic
I/O specifications:
• Current cut-offs should not be used as stop function! This might damage the actuator. Current
cut-offs should only be used in emergencies!
• Current cut-off limits are not proportional with the load curves of the actuator. This means that
the current cut-offs cannot be used as load indicator.
• There are tolerances on the spindle, nut, gear wheels etc. and these tolerances will have an
influence on the current consumption for the specific actuator.
Page 32
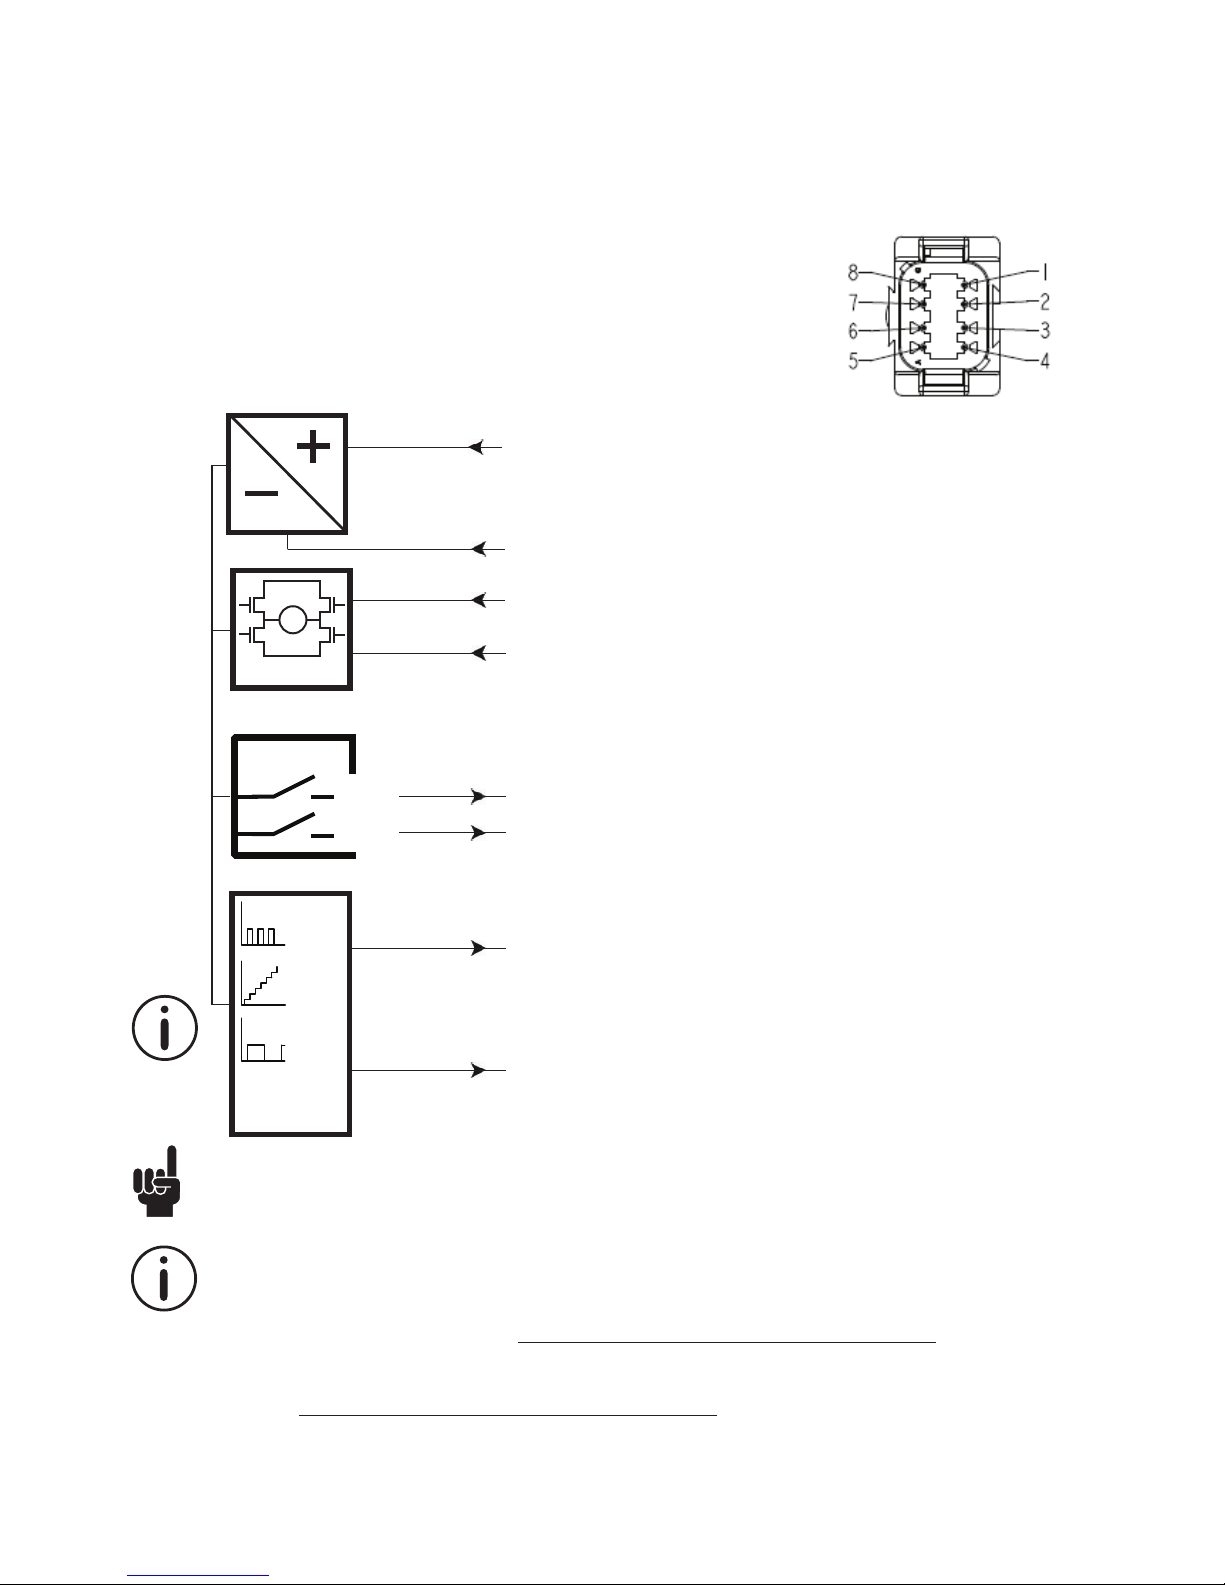
Page 32 of 76
BROWN
BLUE
YELLOW
GREEN
WHITE
VIOLET
BLACK
12/24V DC
RED
INWARDS
OUTWARDS
FEEDBACK
SIGNAL GND
M
H-Bridge
IN
OUT
Hall
0-10V
PWM
4-20mA
50%50%
Actuator with IC Advanced - with BusLink
Connection diagram:
Fig. 10 : 25xxxxxxxxxx3x1x=xxxxx1xxxxxxx
Please be aware that if the power supply is not properly connected, you might damage the actuator!
The BusLink software tool is available for IC Advanced and can be used for:
Diagnostics, manual run and configuration
Download BusLink software here: http://www.linak.com/techline/?id3=2363
For more information and easy set-up of BusLink, please follow this link to view the Quick Guide for
BusLink: http://www.linak.com/techline/?id3=2356
Please note that the BusLink cables must be purchased separately from the actuator!
Item number for BusLink cable kit: 0147999 (adaptor + USB2Lin)
DEUTSCH
8P
2
1
3
4
7
8
6
5
Standard connector front view
Page 33
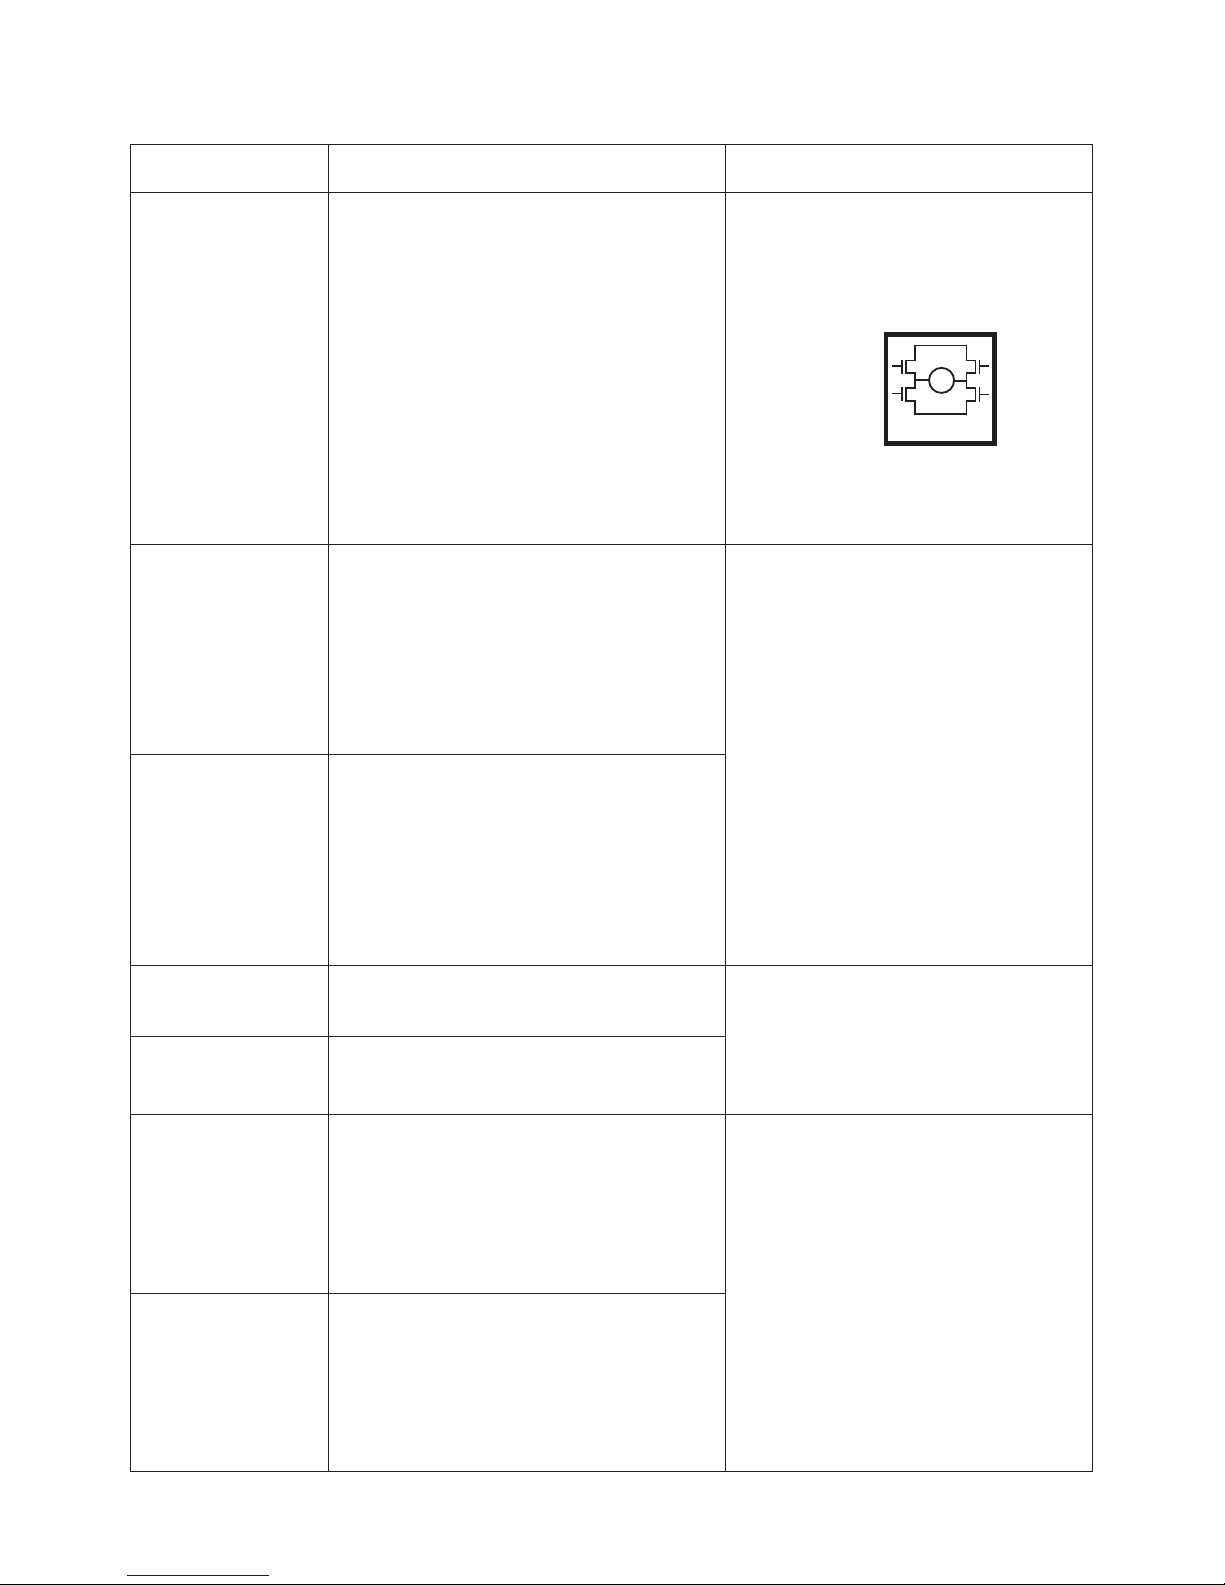
Page 33 of 76
Input/Output Specification Comments
Description Easy to use interface with integrated
power electronics (H-bridge).
The actuator can also be equipped with
electronic circuit that gives an absolute or
relative feedback signal.
IC Advanced provides a wide range of
possibilities for customisation.
The version with “IC option” cannot be
operated with PWM (power supply).
See connection diagram,
fig. 10, page 33
Brown 12-24VDC + (VCC)
Connect Brown to positive
12V ± 20%
24V ± 10%
12V, current limit 8A
24V, current limit 5A
Note: Do not change the power supply
polarity on the brown and blue wires!
Power supply GND (-) is electrically
connected to the housing
Current limit levels can be adjusted
through BusLink
If the temperature drops below -10°C,
all current limits will automatically
increase to 9A for 12V, and 6A for 24V
Blue 12-24VDC - (GND)
Connect Blue to negative
12V ± 20%
24V ± 10%
12V, current limit 8A
24V, current limit 5A
Red Extends the actuator On/off voltages:
> 67% of V
IN
= ON
< 33% of V
IN
= OFF
Input current: 10mA
Black Retracts the actuator
Green Endstop signal out Output voltage min. V
IN
- 2V
Source current max. 100mA
Endstop signals are NOT potential free.
Endstop signals can be configured with
BusLink software according to any
position needed.
When configuring virtual endstop, it is
not necessary to choose the position
feedback
EOS and virtual endstop will work even
when feedback is not chosen
Yellow Endstop signal in
M
H-Bridge
Actuator with IC Advanced - with BusLink
I/O specifications:
Page 34
Page 34 of 76
Input/Output Specification Comment
Violet Analogue feedback (0-10V):
Configure any high/low combination
between 0-10V
Ripple max. 200mV
Transaction delay 20ms
Linear feedback 0.5%
Max. current output. 1mA
Single Hall output (PNP)
Movement per Single Hall pulse:
LA25030 Actuator = 0.25 mm per pulse
LA25060 Actuator = 0.5 mm per pulse
LA25090 Actuator = 0.75 mm per pulse
LA25120 Actuator = 1.0 mm per pulse
LA25200 Actuator = 1.7 mm per pulse
Frequency:
Frequency is 10-20 Hz on Single Hall
output depending on load.
Pulse ON time is minimum 8ms.OFF time
between two ON pulses is minimum 8ms.
Overvoltage on the motor can result in
shorter pulses.
Output voltage min. V
IN
- 2V
Max. current output: 12mA
Max. 680nF
Digital output feedback PWM:
Configure any high/low combination
between 0-100%
Output voltage min. V
IN
- 2V
Frequency: 75Hz ± 10Hz as standard,
but this can be customised.
Duty cycle: Any low/high combination
between 0 and 100 percent.
Open collector source current max.
12mA
Analogue feedback (4-20mA):
Configure any high/low combination
between 4-20mA
Tolerances +/- 0.2mA
Transaction delay 20ms
Linear feedback 0.5%
Output: Source
Serial resistance:
12V max. 300 ohm
24V max. 900 ohm
All absolute value feedbacks
(0-10V, PWM and 4-20mA)
Standby power consumption:
12V, 60mA
24V, 45mA
It is recommendable to have the actuator to activate its limit switches on a
regular basis, to ensure more precise
positioning
White Signal GND
For correct wiring of power GND and
Signal GND see page 36
Actuator with IC Advanced - with BusLink
I/O specifications:
Page 35
Page 35 of 76
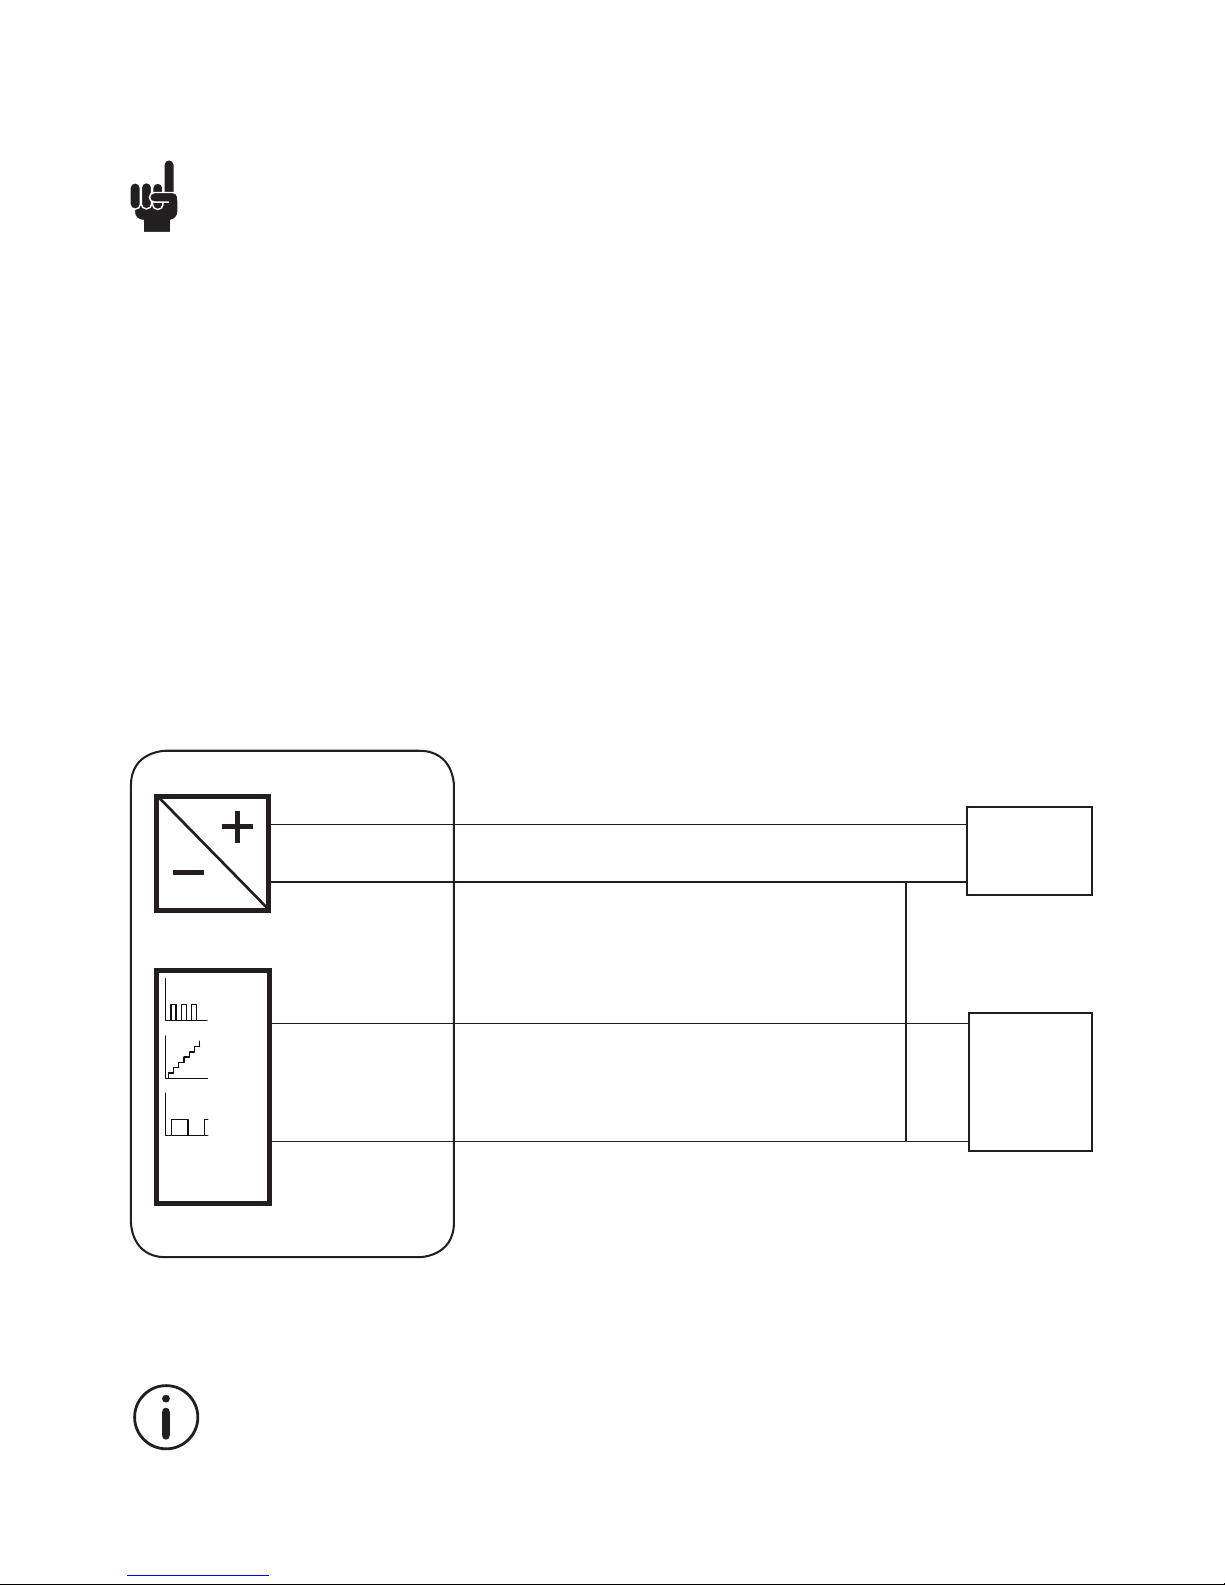
When using the feedback output, it is important to use the right connection setup. Attention should be paid to
the two ground connections. Power GND in the Power connector and Signal GND in the Control connector. When
using either 0-10V, Hall or PWM feedback, the Signal GND must be used. For optimal accuracy, the Signal GND
is connected to the Power GND as close as possible to the feedback input equipment.
FEEDBACK
SIGNAL GND
50%50%
Hall
0-10V
PWM
4-20mA
Power
supply
Feedback
input
Power connector
Control connector
POWER
POWER GND
LA25 IC actuator
WHITE
VIOLET
BROWN
BLUE
50%
50%
Please note that this section only applies for the following feedback options:
0-10V, Hall and PWM.
Correct wiring of Power GND and Signal GND for IC Basic and IC Advanced
Actuator with IC Advanced - with BusLink
• Current cut-offs should not be used as stop function! This might damage the actuator. Current cutoffs should only be used in emergencies!
• Current cut-off limits are not proportional with the load curves of the actuator. This means that the
current cut-offs cannot be used as load indicator.
• There are tolerances on the spindle, nut, gear wheels etc. and these tolerances will have an
influence on the current consumption for the specific actuator.
Page 36
Page 36 of 76
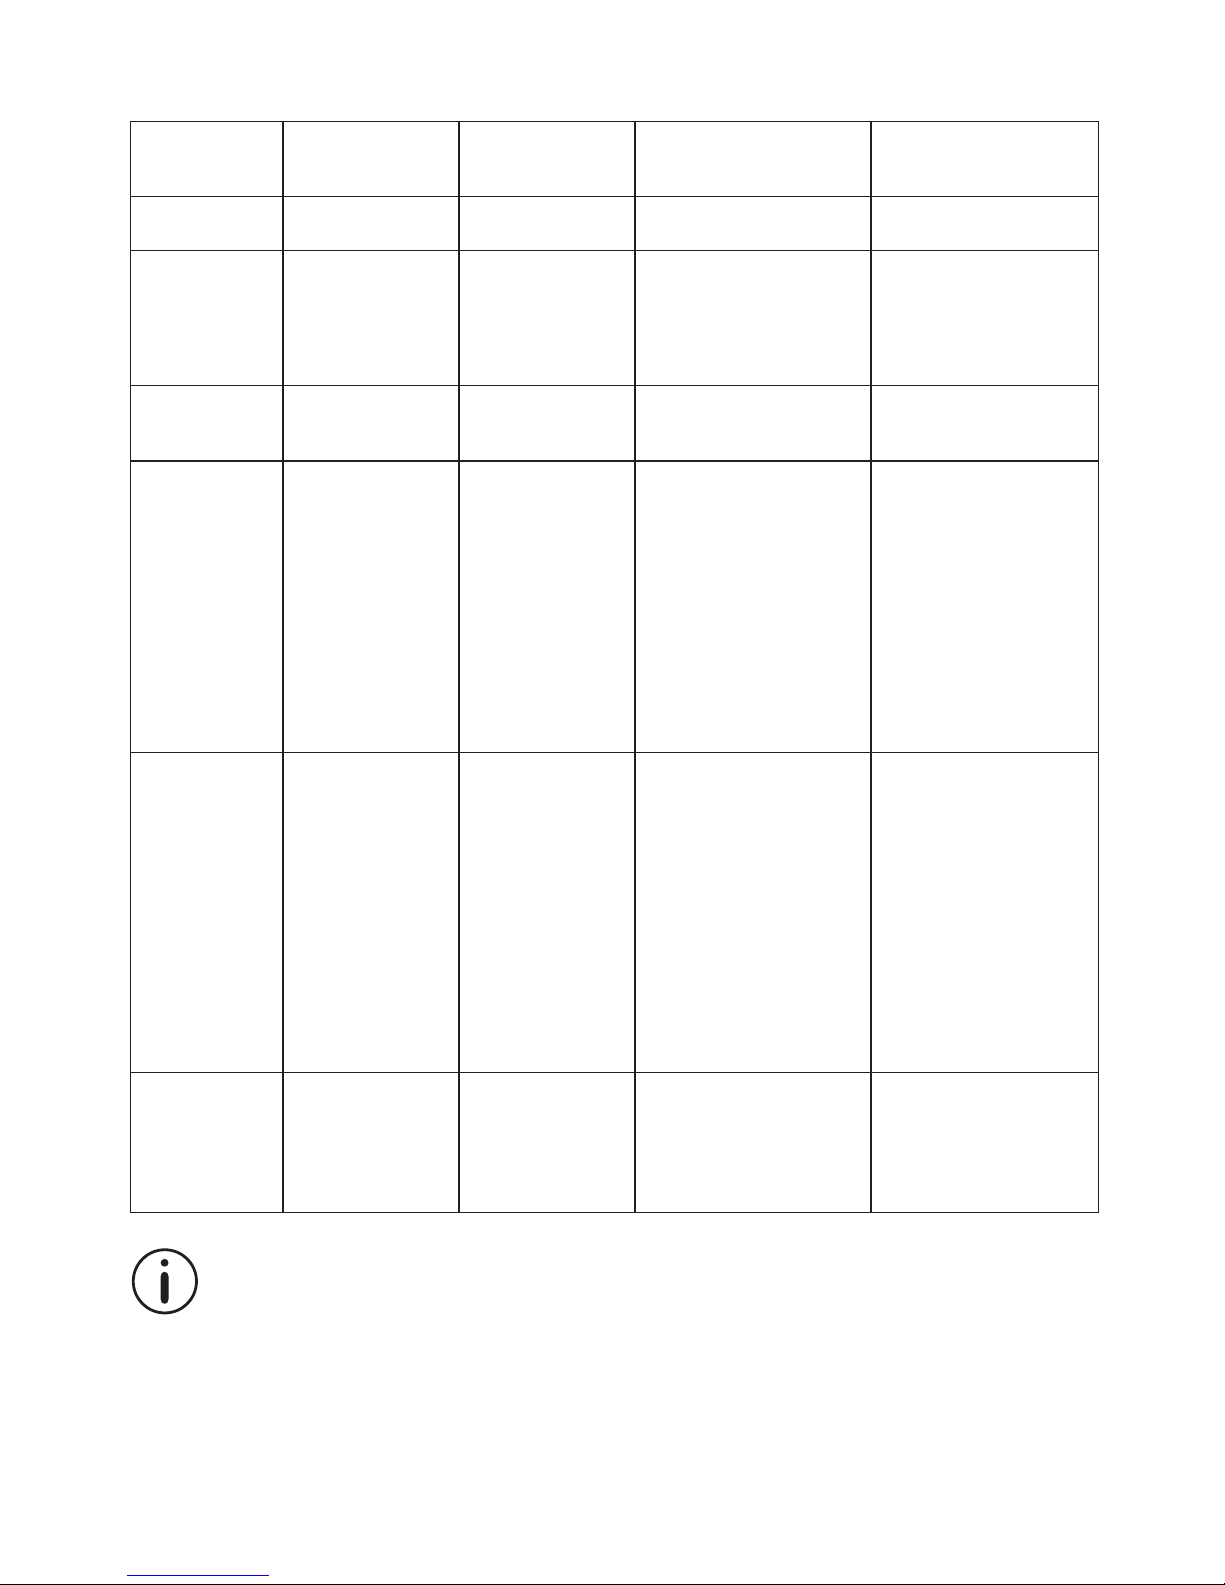
IC options overview
Control
12V, 24V supply √ √ √ √ √
Basic Advanced Parallel LIN bus CAN bus
H-bridge √ √ √ √ √
Manual drive in/out √ √ √ √ √
EOS in/out - √ √ √ -
Soft start/stop √ √ √ √ √
Feedback
Voltage √ √ * - - -
Current - √ ** - - -
Single Hall √ √ - - -
PWM - √ - - -
Position (mm) - - - √ √
Custom feedback type - √ - - -
Monitoring
Temperature monitoring √ √ √ √ √
Current cut-off √ √ √ √ √
Ready signal - - - - -
BusLink
Service counter - √ √ √ √
Custom soft start/stop - √ *** √ *** √ *** √***
Custom current limit - √ √ √ √ √
Speed setting - √ √ √ √
Virtual end stop - √ √ √ √
* Configure any high/low combination between 0 - 10V
*** Configure any value between 0 - 30s
** Configure any high/low combination between 4 - 20mA
Page 37
Page 37 of 76
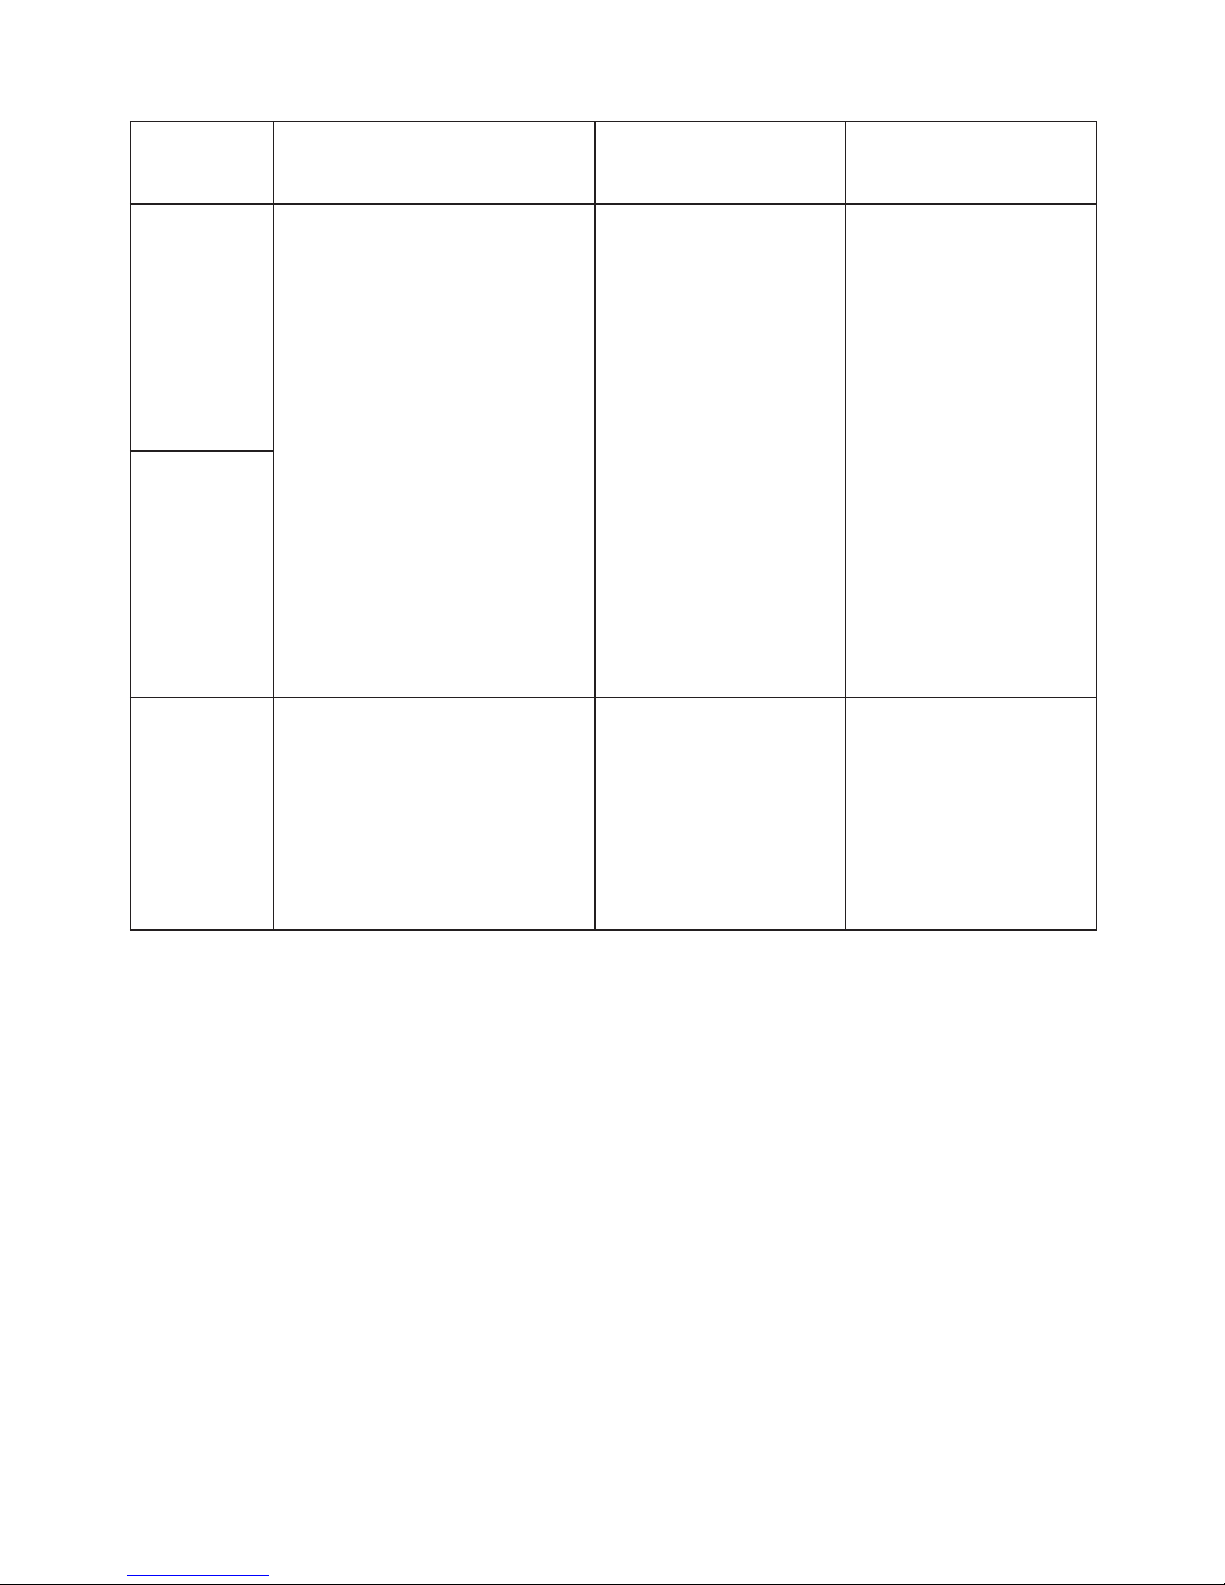
Feedback configurations available for IC Basic, IC Advanced and Parallel
Pre-configured Customised
range
Pros Cons
None N/A N/A
PWM
Feedback
10 – 90 %
75 Hz
0 – 100 %
75 – 150 Hz
Suitable for long
distance transmission.
Effectual immunity to
electrical noise.
More complex
processing required,
compared to AFV and
AFC.
Single Hall* N/A N/A Suitable for long
distance transmission.
No position indication.
Analogue
Feedback
Voltage
(AFV)*
0 - 10V Any
combination,
going negative
or positive.
E.g. 8.5 – 2.2V
over a full
stroke.
High resolution.
Traditional type of
feedback suitable for
most PLCs.
Easy faultfinding.
Independent on stroke
length, compared to a
traditional mechanical
potentiometer.
Not recommended
for applications with
long distance cables or
environments exposed
to electrical noise.
Analogue
Feedback
Current (AFC)
4 - 20mA Any
combination,
going negative
or positive.
E.g. 5.5 – 18mA
over a full
stroke.
High resolution. Better
immunity to long cables
and differences in
potentials than AFV.
Provides inherent error
condition detection.
Independent on stroke
length, compared to a
traditional mechanical
potentiometer.
Not suitable for signal
isolation.
Endstop
signal in/
out**
At physical end
stops.
Default for IC
Advanced.
Any position.
(Not IC Basic)
Can be set at any
position over the full
stroke length.
(Not IC Basic)
Only one endstop can
be customised.
(Not IC Basic)
All feedback configurations are available for IC Advanced.
* IC Basic feedback configurations available: Single Hall and 0-10V
** Parallel feedback configurations available: EOS
Page 38
Page 38 of 76
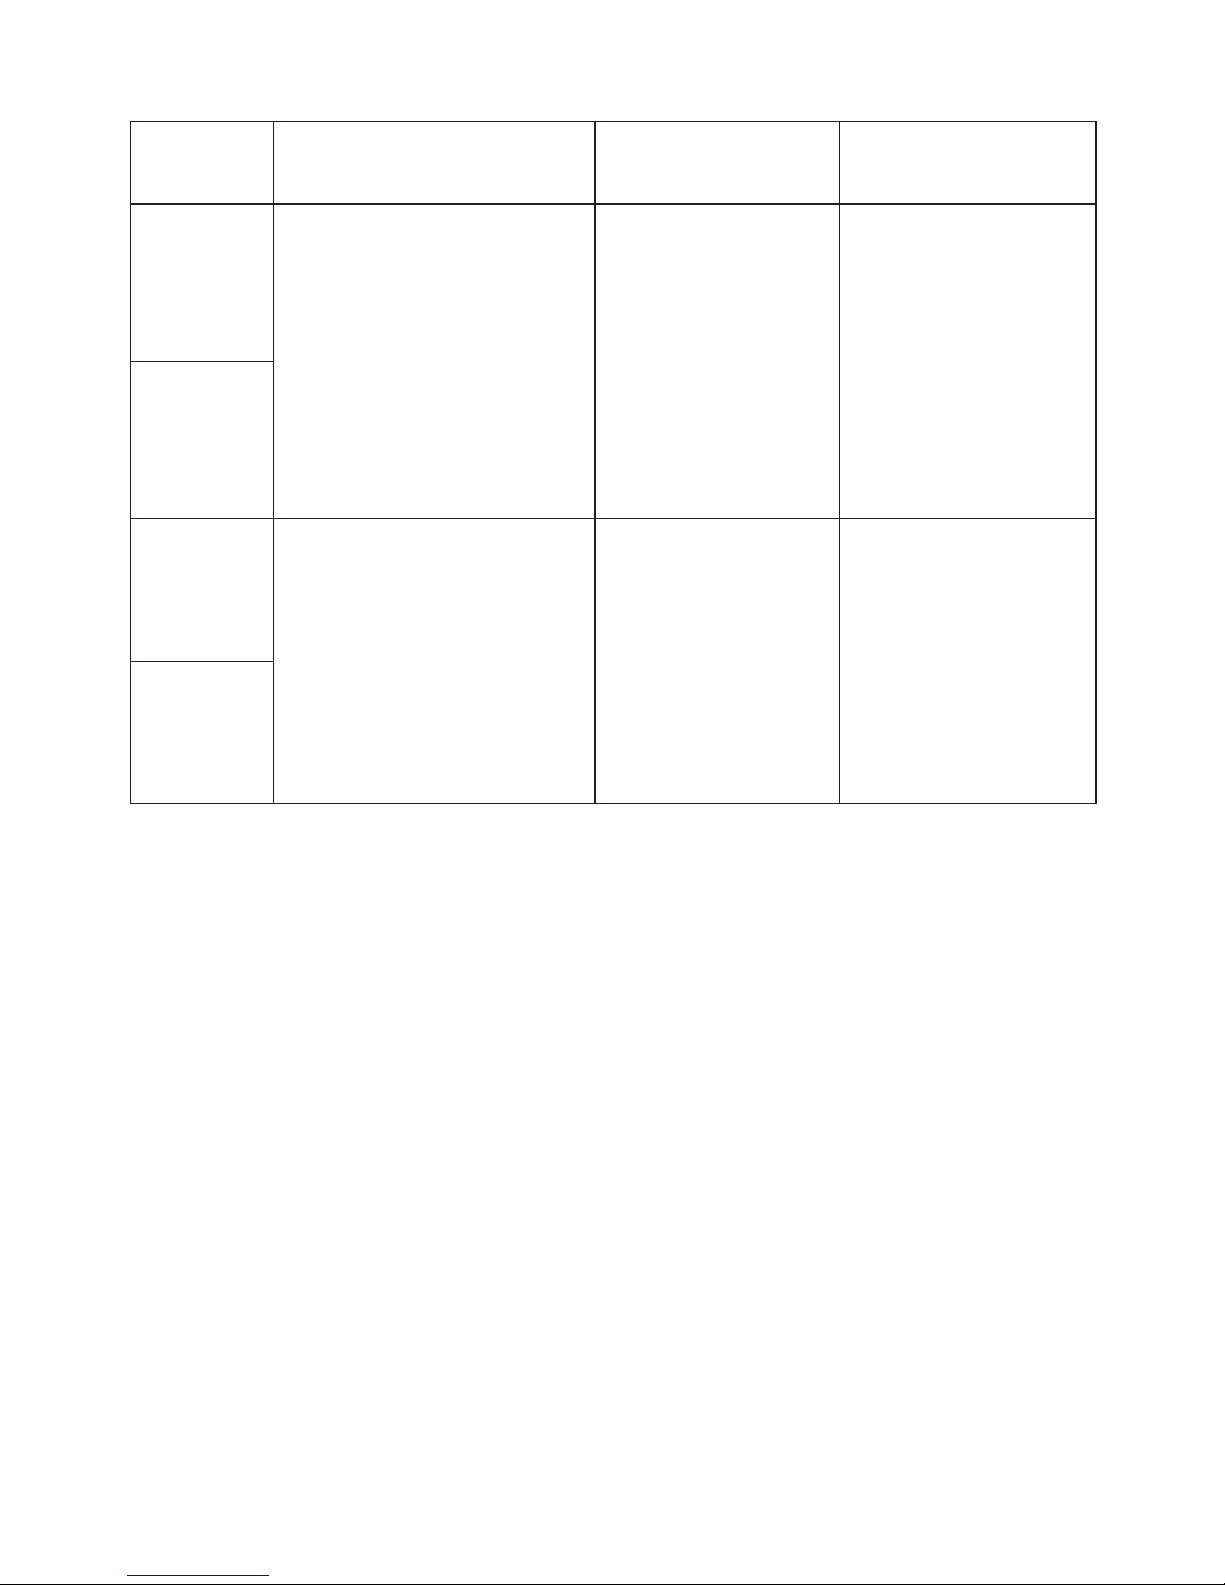
Actuator configurations available for IC Basic, IC Advanced and Parallel
Pre-configured Customised range
(Not IC Basic)
Description
Current limit
inwards
20A for both current limit directions. (When the current outputs
are at zero, it means that they are
at maximum value 20A).
Be aware:
When the actuator comes with
current cut-off limits that are
factory pre-configured for certain
values, the pre-configured values
will be the new maximum level of
current cut-off.
This means that if the current
cut-off limits are pre-configured
to 14A, it will not be possible to
change the current limits through
BusLink to go higher than 14A.
Recommended range: 4A
to 20A
If the temperature drops
below 0°C, all current
limits will automatically
increase to approximately
30A, indenpendent of
the pre-configured value.
The actuator’s unloaded
current consumption is
very close to 4A, and
if the current cut-off is
customised below 4A
there is a risk that the
actuator will not start.
The inwards and outwards current limits can
be configured separately
and do not have to have
the same value.
Current limit
outwards
Max. speed
inwards/
outwards
100% equal to full performance.
Please note: for parallel actuators
the full performance equals 80%
of the max. speed.
Lowest recommended
speed at full load: 60%
It is possible to reduce
the speed below 60%,
but this is dependable on
load, power supply and
the environment.
The speed is based on a
PWM principle, meaning
that 100% equals the
voltage output of the
power supply in use, and
not the actual speed.
Page 39
Page 39 of 76
Actuator configurations available for IC Basic, IC Advanced and Parallel
Pre-configured Customised range
(Not IC Basic)
Description
Soft stop
inwards
0.3 sec. for both soft stop
directions.
0.3 sec. to 30 sec.
0 sec. can be chosen for
hard stop.
It is not possible to configure values between
0.01 sec. to 0.29 sec.
This is due to the backEMF from the motor
(increasing the voltage).
Be aware that the soft
stop value equals the
deacceleration time after
stop command.
Soft stop
outwards
Soft start
inwards
0.3 sec. for both soft start
directions.
0 sec. to 30 sec. Be aware that the soft
start value equals the
acceleration time after
start command.
To avoid stress on the
actuator, it is not recommended to use 0 sec. for
soft start, due to higher
inrush current.
Soft start
outwards
Page 40
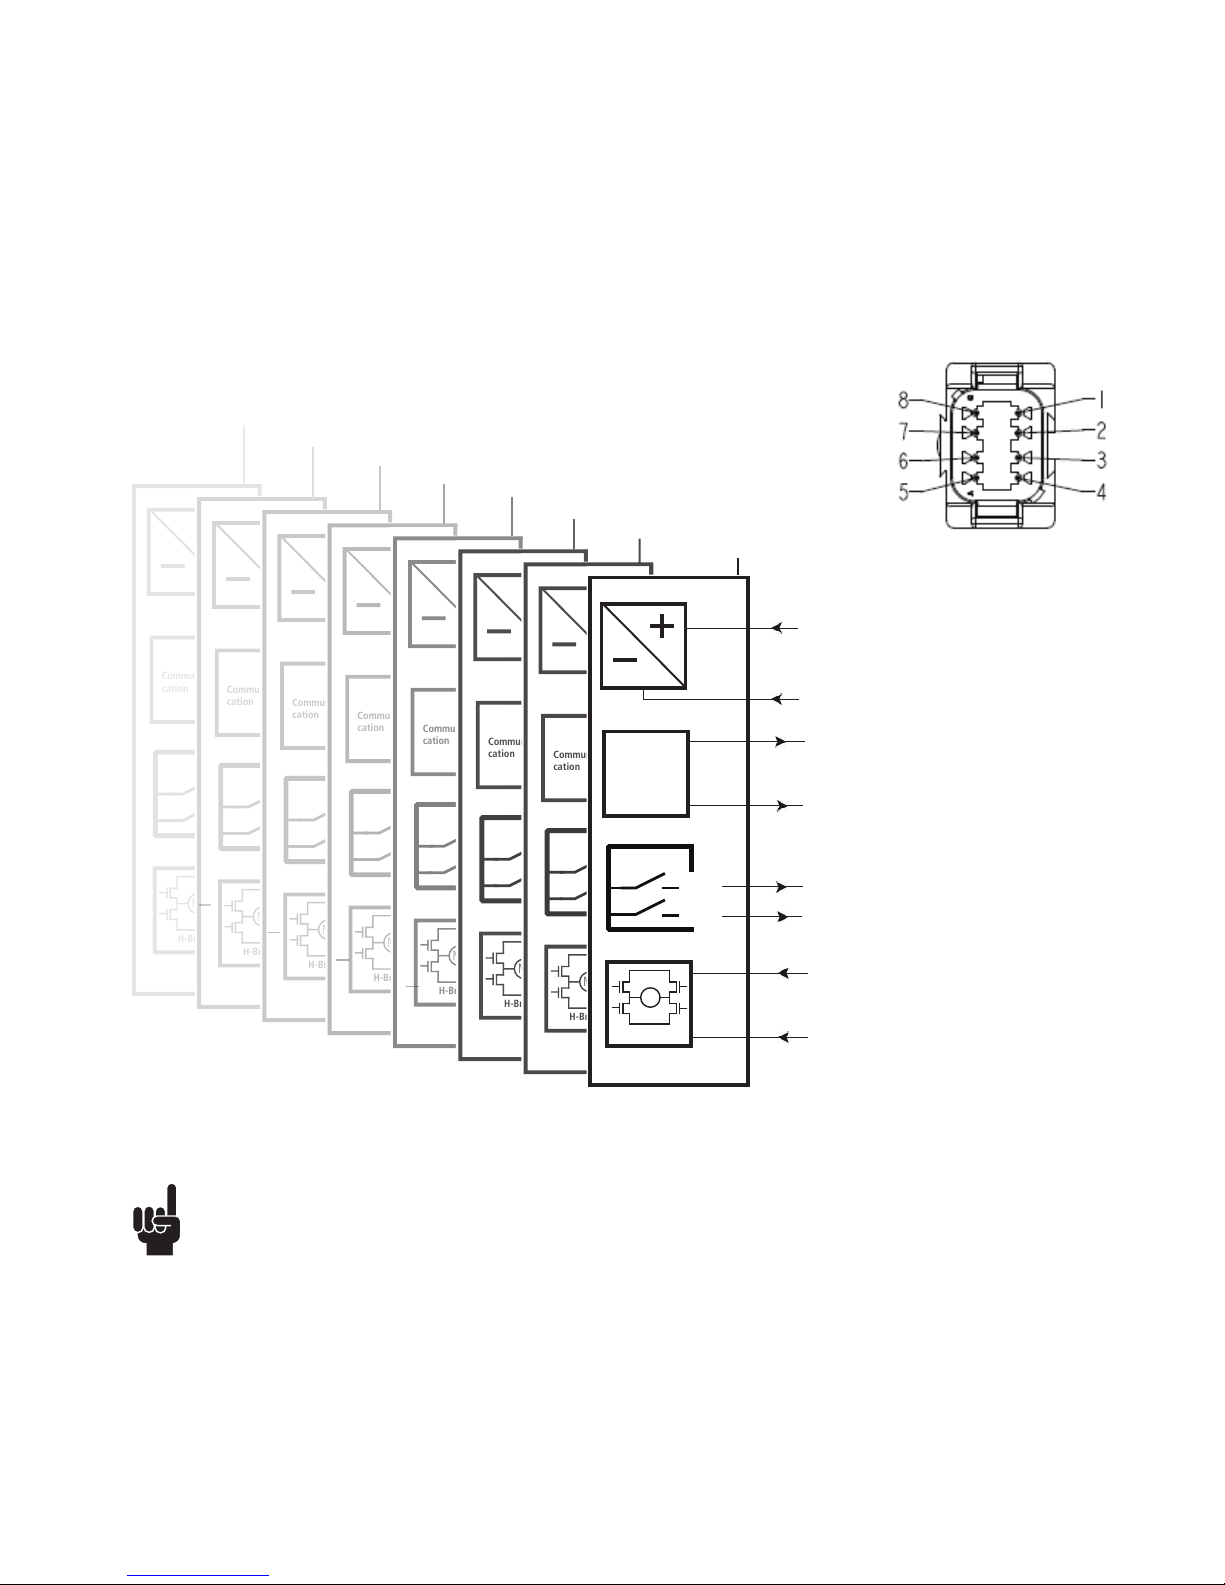
Page 40 of 76
Fig. 11 : 25xxxxxxxxxx3x1x=xxxxx1Zxxxxxx
Actuator 1
Actuator 2
Actuator 3
Actuator 4
Actuator 5
Actuator 6
Actuator 7
Actuator 8
INWARDS
OUTWARDS
M
H-Bridge
Communi-
cation
IN
OUT
INWARDS
OUTWARDS
M
H-Bridge
Communi-
cation
IN
OUT
INWARDS
OUTWARDS
M
H-Bridge
Communi-
cation
IN
OUT
INWARDS
OUTWARDS
M
H-Bridge
Communi-
cation
IN
OUT
INWARDS
OUTWARDS
M
H-Bridge
Communi-
cation
IN
OUT
INWARDS
OUTWARDS
M
H-Bridge
Communi-
cation
IN
OUT
INWARDS
OUTWARDS
M
H-Bridge
Communi-
cation
IN
OUT
12/24V DC
BLACK
RED
INWARDS
OUTWARDS
M
H-Bridge
BROWN
Communication
WHITE
VIOLET
YELLOW
GREEN
IN
OUT
BLUE
Actuator with Parallel
Connection diagram:
• Please be aware that if the power supply is not properly connected, you might damage the actuator!
• The green and yellow wires from parallel connected actuators must NOT be interconnected.
Standard connector front view
DEUTSCH
8P
2
1
3
4
7
6
8
5
Page 41
Page 41 of 76
Input/Output Specification Comments
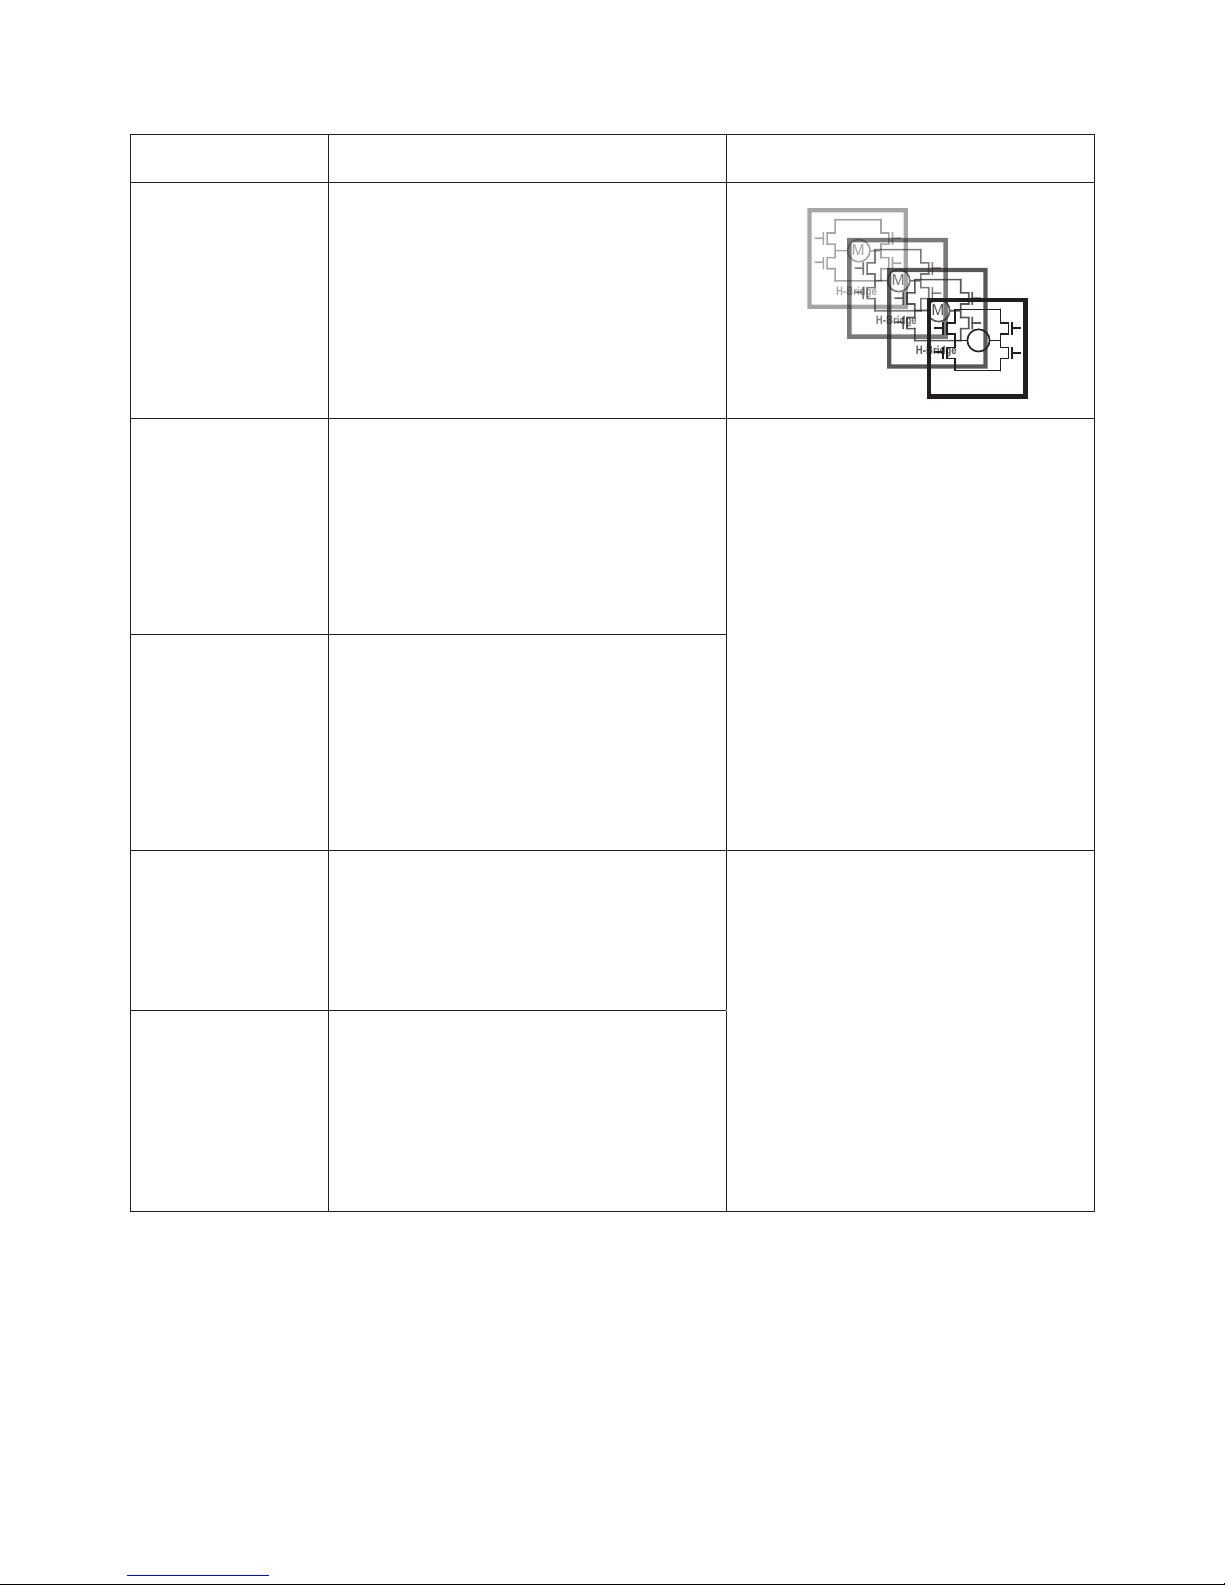
Description Parallel drive of up to 8 actuators. A
master actuator with an integrated
H-bridge controller controls up to 7 slaves.
The version with “IC option” cannot be
operated with PWM (power supply).
See connection diagram,
fig. 11, page 41
Brown 12-24VDC + (VCC)
Connect Brown to positive
12V ± 20%
24V ± 10%
12V, current limit 8A
24V, current limit 5A
Note: Do not change the power supply
polarity on the brown and blue wires!
The parallel actuators can run on one
OR separate power supplies
Power supply GND (-) is electrically
connected to the housing
Current limit levels can be adjusted
through BusLink (only one actuator at a
time for parallel)
If the temperature drops below -10°C,
all current limits will automatically
increase to 9A for 12V, and 6A for 24V
Blue 12-24VDC - (GND)
Connect Blue to negative
12V ± 20%
24V ± 10%
12V, current limit 8A
24V, current limit 5A
Red Extends the actuator On/off voltages:
> 67% of V
IN
= ON
< 33% of V
IN
= OFF
Input current: 10mA
It does not matter where the in/out sig
nals are applied. You can either choose
to connect the signal cable to one
actuator OR you can choose to connect the signal cable to each actuator
on the line. Either way this will ensure
parallel drive
Black Retracts the actuator
Actuator with Parallel
I/O specifications:
M
H-Bridge
M
H-Bridge
M
H-Bridge
M
H-Bridge
Page 42
Page 42 of 76
Input/Output
Specification
Comment
Green Endstop signal out Output voltage min. V
IN
-
2V
Source current max. 100mA
Endstop signals are NOT potential free.
Endstop signals can be configured with
BusLink software according to any position needed
Yellow Endstop signal in
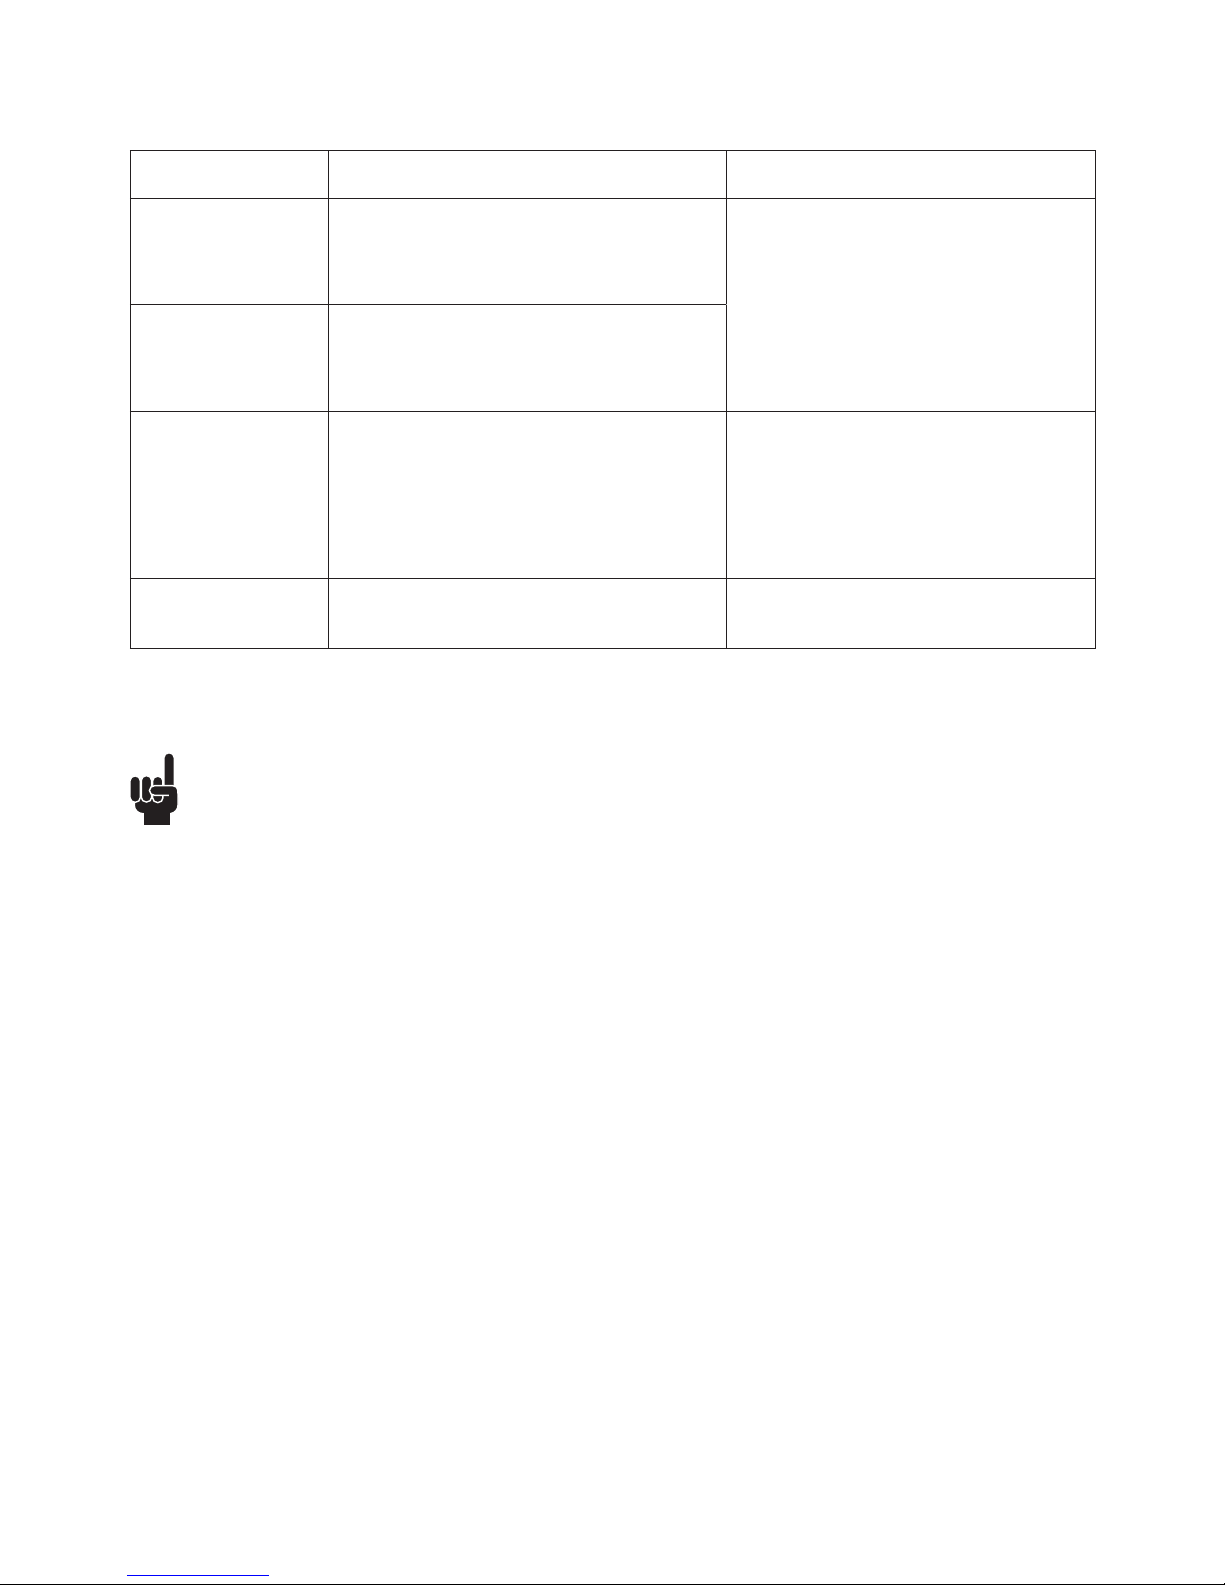
Violet Parallel communication:
Violet cords must be connected together
Standby power consumption:
12V, 60mA
24V, 45mA
No feedback available during parallel
drive
White Signal GND:
White cords must be connected together
For correct wiring of power GND and
Signal GND see page 36
Actuator with Parallel
I/O specifications:
• Current cut-offs should not be used as stop function! This might damage the actuator. Current
cut-offs should only be used in emergencies!
• Current cut-off limits are not proportional with the load curves of the actuator. This means that the
current cut-offs cannot be used as load indicator.
• There are tolerances on the spindle, nut, gear wheels etc. and these tolerances will have an
influence on the current consumption for the specific actuator.
Page 43
Page 43 of 76
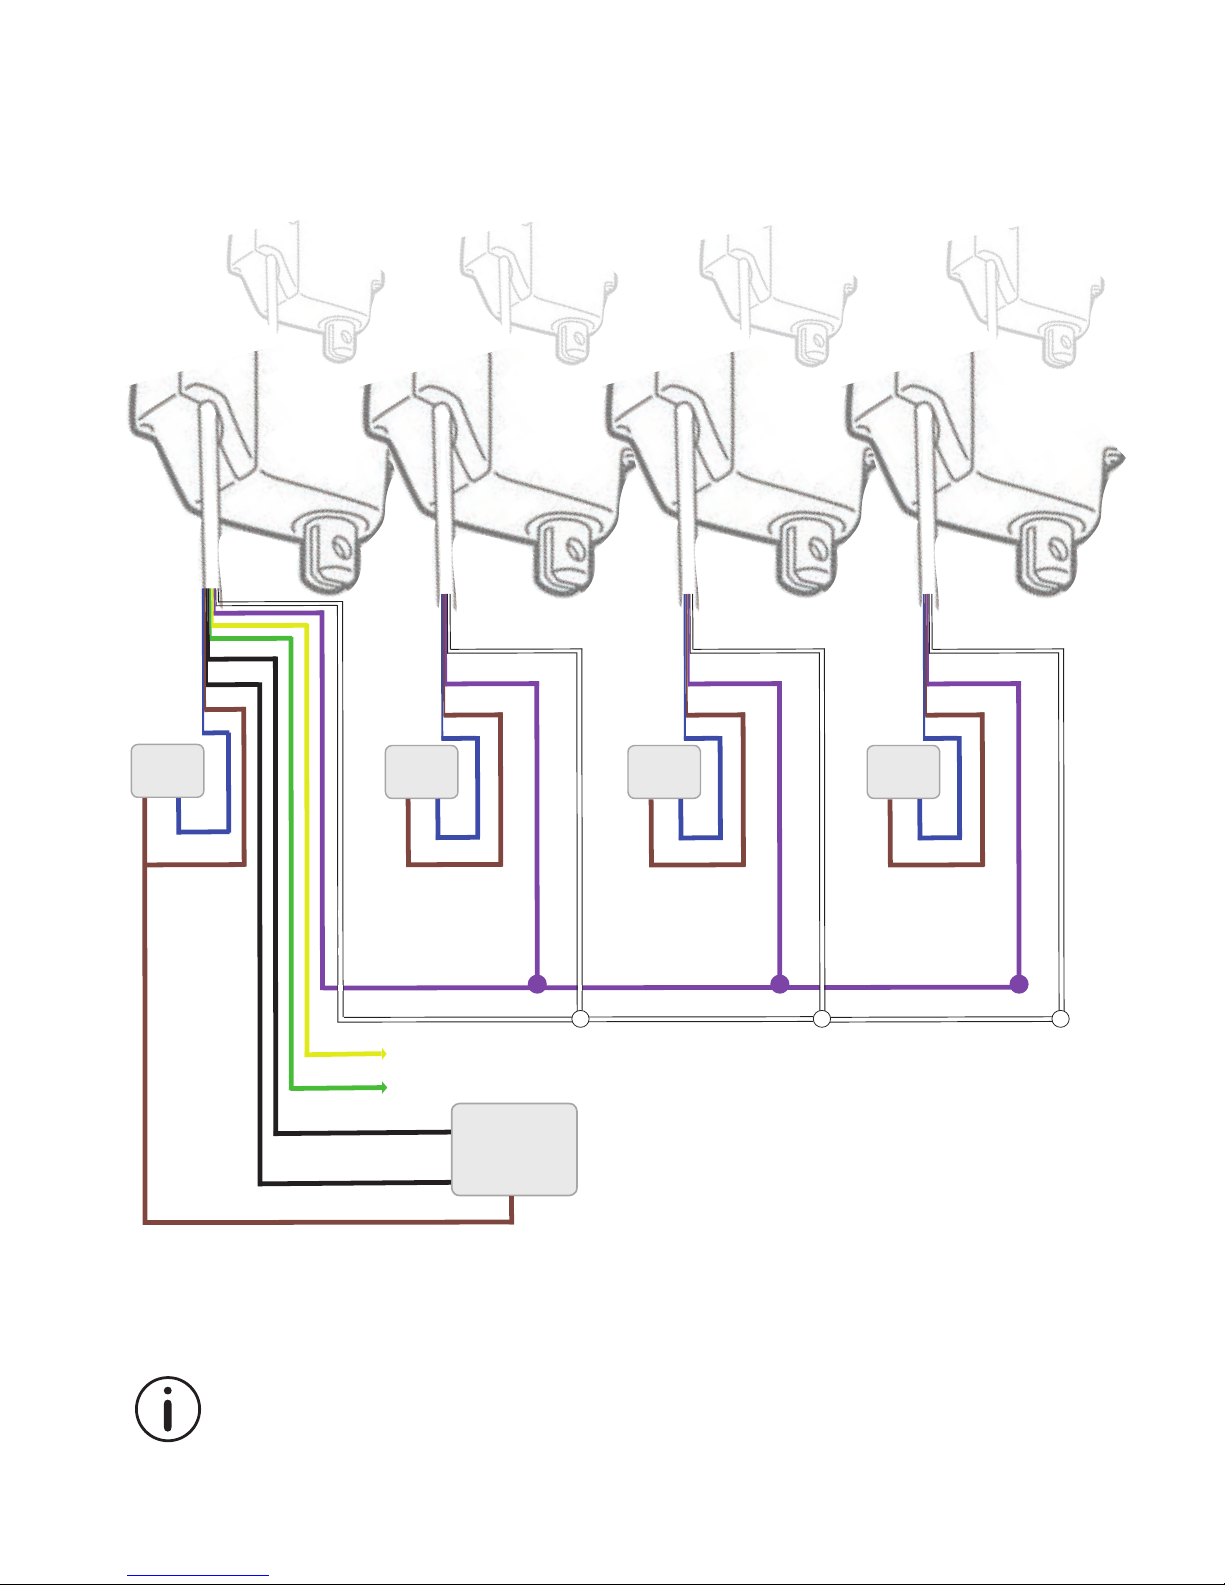
• It is both possible to run parallel with a single power supply, or to run each actuator with
separate power supplies.
• Only standard power and signal cables are available for parallel.
The parallel system
The parallel drive function will support a number of actuators working jointly.
Controller/
Rocker Switch
ENDSTOP
IN
ENDSTOP
OUT
BROWN
BLUE
+ -
GREEN
YELLOW
RED (OUT)
BLACK (IN)
WHITE Signal GND
RED
BLACK
Power
Supply
12/24V
+
-
VIOLET Communication
Power
Supply
12/24V
Power
Supply
12/24V
Power
Supply
12/24V
+
-
+
-
Page 44
Page 44 of 76
Buslink software tool and the parallel system
The BusLink software tool is available for parallel and can be used for:
Configuration, Manual run and Diagnostics (service counter)
The BusLink software can be downloaded on: http://www.linak.com/techline/?id3=2363
For more information and easy set-up of BusLink, please follow this link to view the Quick Guide for BusLink:
http://www.linak.com/corporate/pdf/ENGLISH/BROCHURE/TECHLINE_BusLink%20Quick%20Guide_Brochure_Eng.pdf
Please note that the BusLink cables must be purchased separately from the actuator!
Item number for BusLink cable kit: 0147999 (adaptor + USB2Lin)
Only through the BusLink software tool is it possible to state if the system is Parallel or Non-critical
Parallel. Via this tool it is also possible to reconfigure the whole system from one system to the other.
The parallel system
• The system does not have to run on one main power supply only – it can be supplied by individual supplies
corresponding to the number of actuators in the system. Please respect the actuator specifications regarding
voltage level and current consumption!
• It does not matter where the IN/OUT signal is applied. The signals of all actuators can be connected together
• When all actuators are connected, a Master will automatically be chosen. E.g. with 5 actuators in one system
there will be 1 Master and 4 Slaves. The Master can control up to 7 slaves
• If an overload occurs, the running of the actuators will be stopped and blocked in that direction until an
activation in the opposite direction has been made, or the system has been re-powered
• Before entering BusLink mode, all actuators must be disconnected. It is only possible to configure one actuator
at a time through BusLink
• When changing the actuator configuration, it is important that all actuators in the system have the same
configuration before the system starts running. Otherwise, the actuators will not run
• Actuators will be pre-programmed from our production as 2, 3, 4, 5.. etc. parallel systems. Through BusLink it
will be possible to add or remove actuators to/from the system
• In case an actuator drops off the line due to e.g. a damaged signal cable, the parallel system will stop
immediately
• In case one of the actuators are broken, the system will not move; not even after re-powering. The broken
actuator needs to be replaced, before the system can run again. The system will only run when it is complete
or configured to a Non-critical Parallel system via the Buslink software tool
Page 45
Page 45 of 76
Only for Non-critical Parallel systems
• The Non-critical Parallel system offers auto-detection for every single power up if a new actuator is added
to the line (system)
• To add or remove actuators from the system, the system needs to be shut down and powered up again.
Please be aware, that after re-powering, the system will not detect if an actuator is missing!
• If adding a new actuator to the system, be aware that the actuator needs to have the same configuration
(Non-critical Parallel) as the existing ones; this can be done via the Buslink software tool.
Page 46
Page 46 of 76
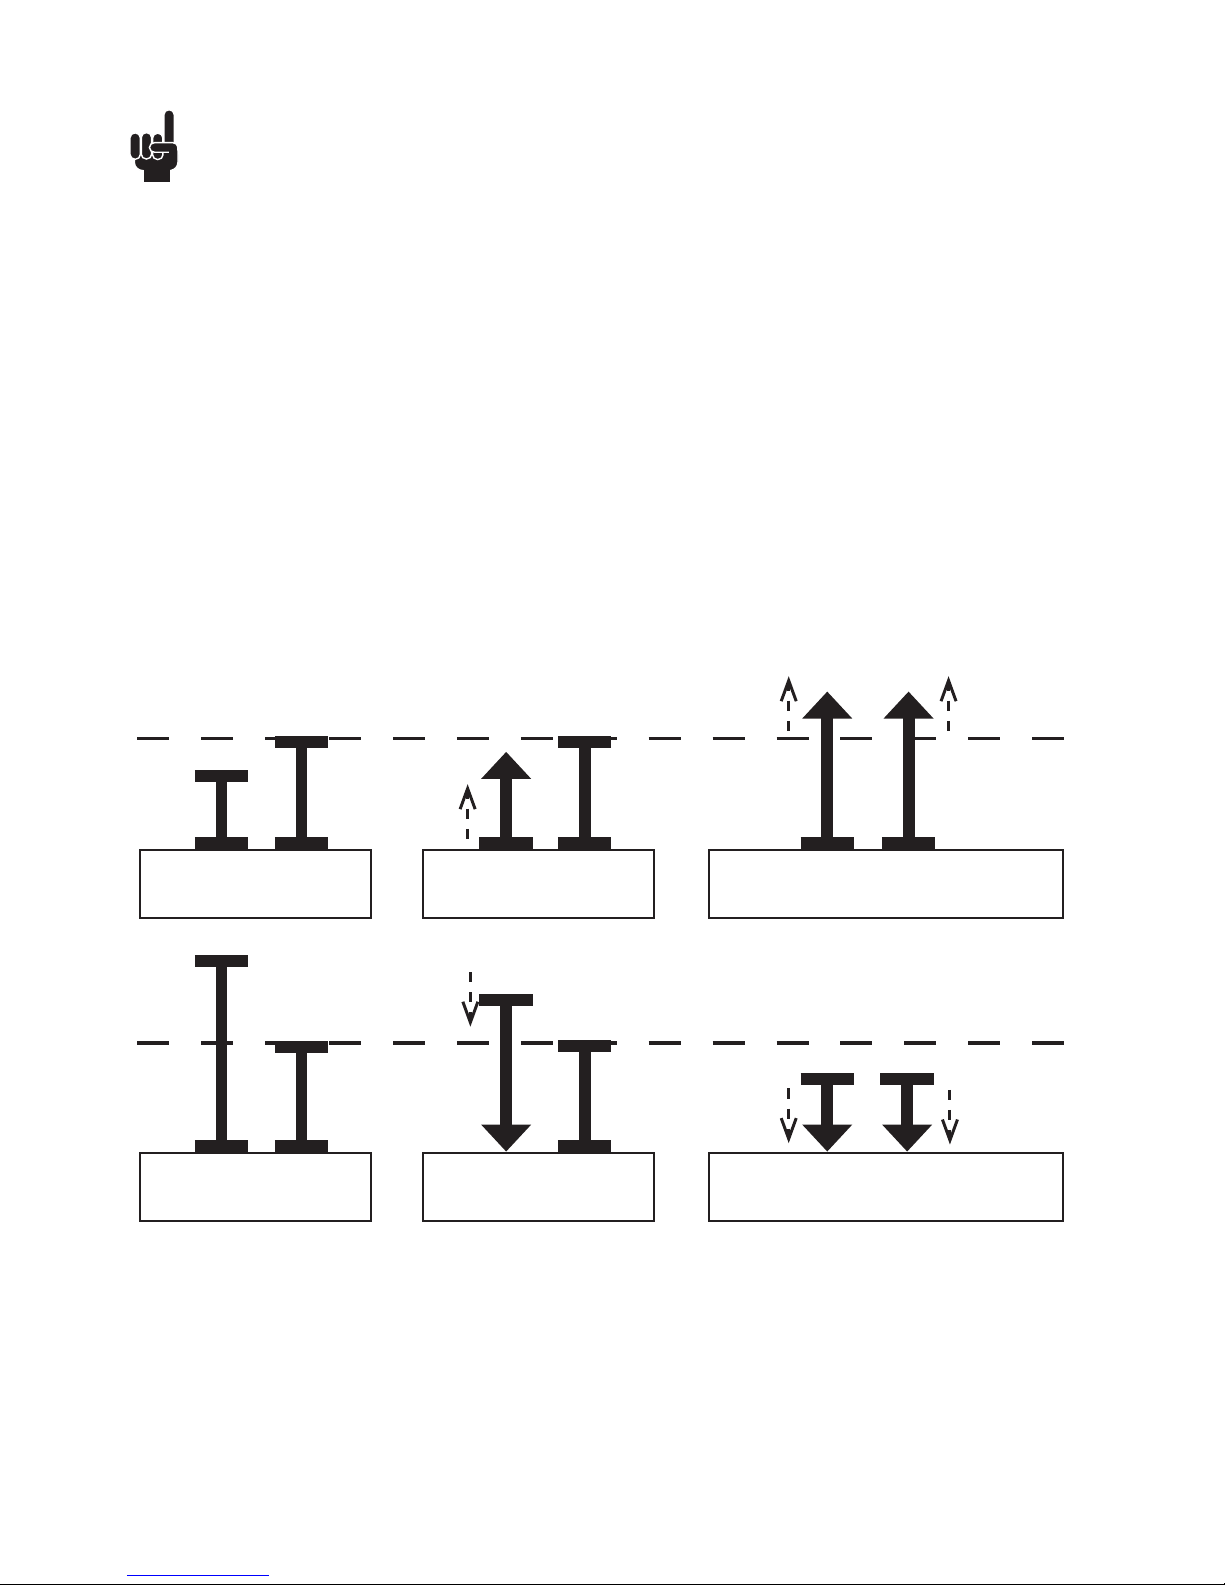
If the actuators are not in parallel when starting up, the next movement will run in the following manner:
System Monitoring for Parallel
Alignment of the parallel actuator system
Start position
Running outwards
When completely aligned, the
parallel run continues outwards
Start position
Running inwards
When completely aligned, the
parallel run continues inwards
If one of the actuators have one of the following error conditions, the actuator will immediately
STOP:
• H-Bridge fault
• Out of the temperature range (High duty cycle protection)
• Overcurrent (Current cut-off if one or all actuators go in mechanical block)
• SMPS fault
• EOS fault switch
• Hall sensor failure
• Position lost
• Overvoltage (43V DC)
Page 47
Page 47 of 76
Parallel manual service mode
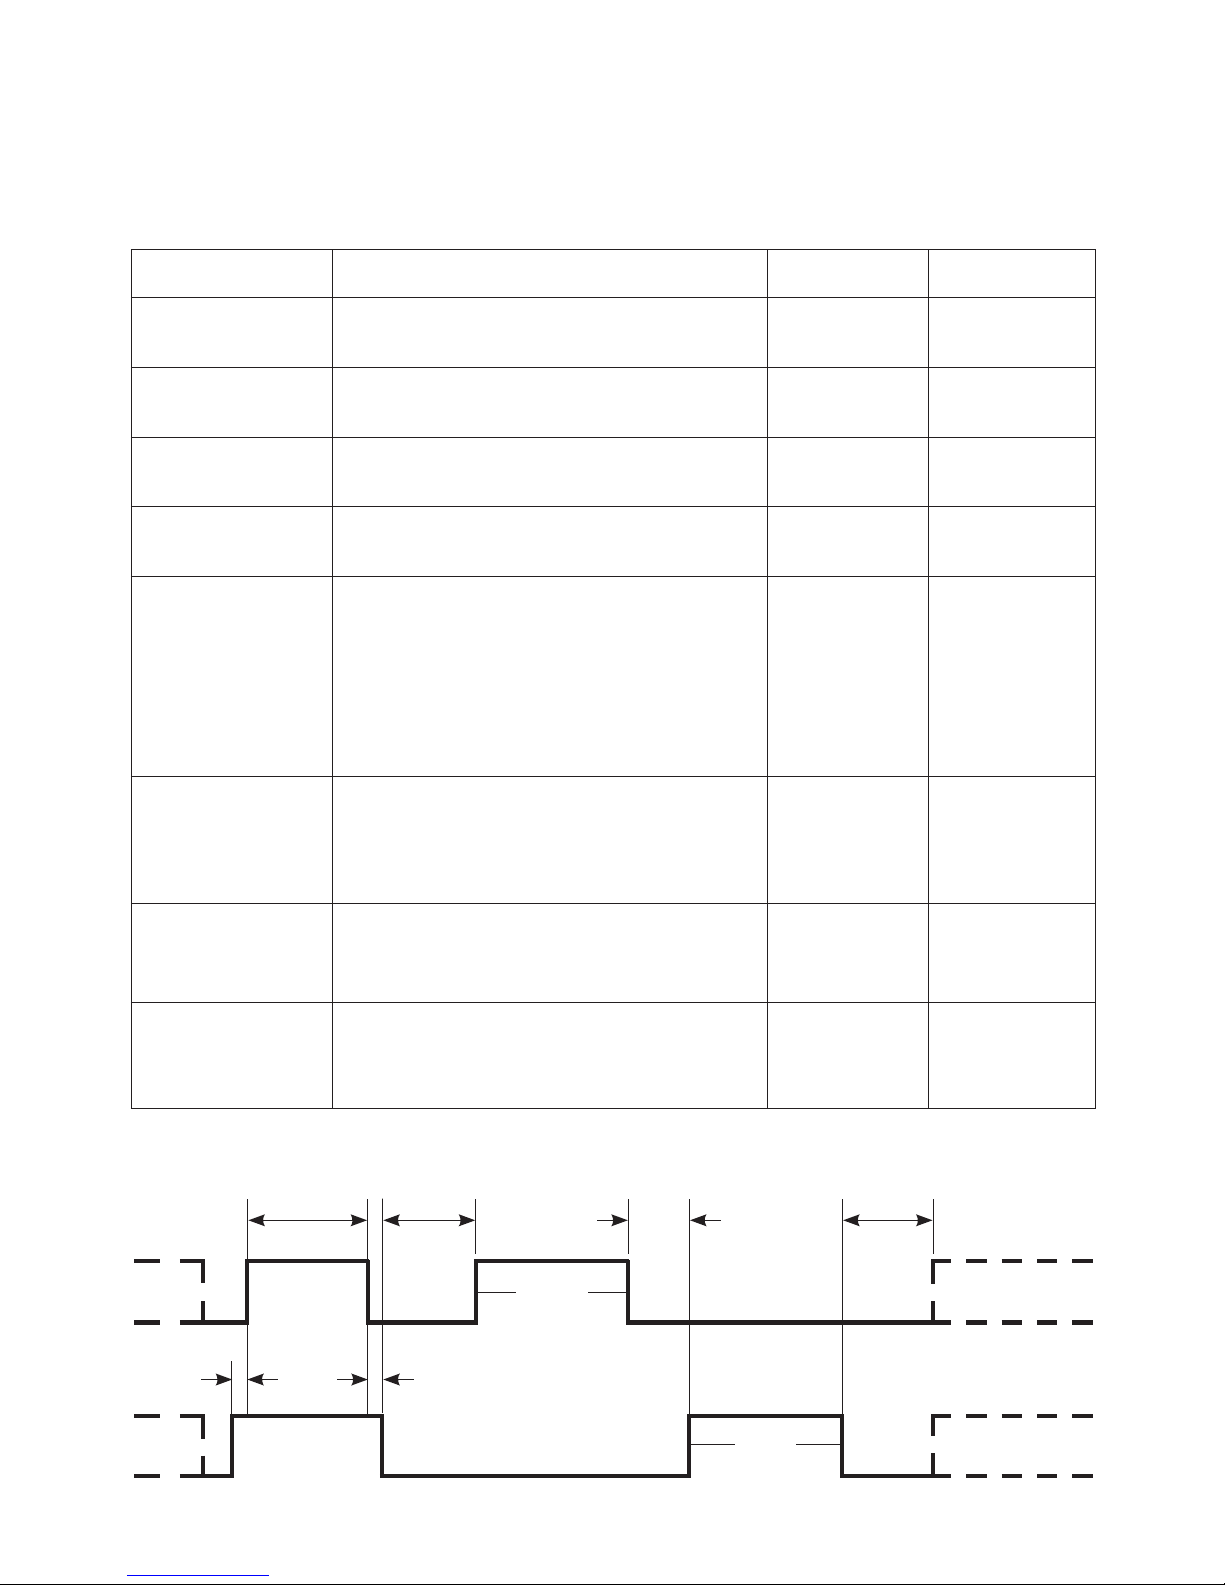
With the parallel manual service mode it is possible to drive one or more parallel actuators separately, using the
red and black wire from each actuator.
Please follow this procedure to manually extend/retract the parallel actuator(s):
Procedure Min. Max.
First step Disconnect the Purple and White wires
between all actuators
- -
Hold Put power on the Red and Black wires for
10-30 seconds
10 sec. 30 sec.
Difference The Red and Black wires must all be connected
to the power supply within 0.5 seconds
0 sec. 0.5 sec.
Release Disconnect all wires and wait 0.5-2 seconds
before the next step
0.5 sec. 2 sec.
Extend/Retract Now choose either to extend or retract the
actuator:
To extend the actuator: Connect only the Red
wire(s) to the power supply
To retract the actuator: Connect only the Black
wire(s) to the power supply
- -
Interval Switch between running in/out as much as
needed, without exceeding the 2.0 seconds
interval between disconnecting/connecting the
Red and Black wires
- 2 sec.
End To exit the parallel manual mode, diconnect
the Red and Black wires for more than 2.0
seconds
2 sec. -
Back to parallel
mode
Before running in standard parallel mode,
reconnect all Purple and White wires
- -
Run in
Run out
Hold Release End
Interval
Difference
Difference
Page 48
Page 48 of 76
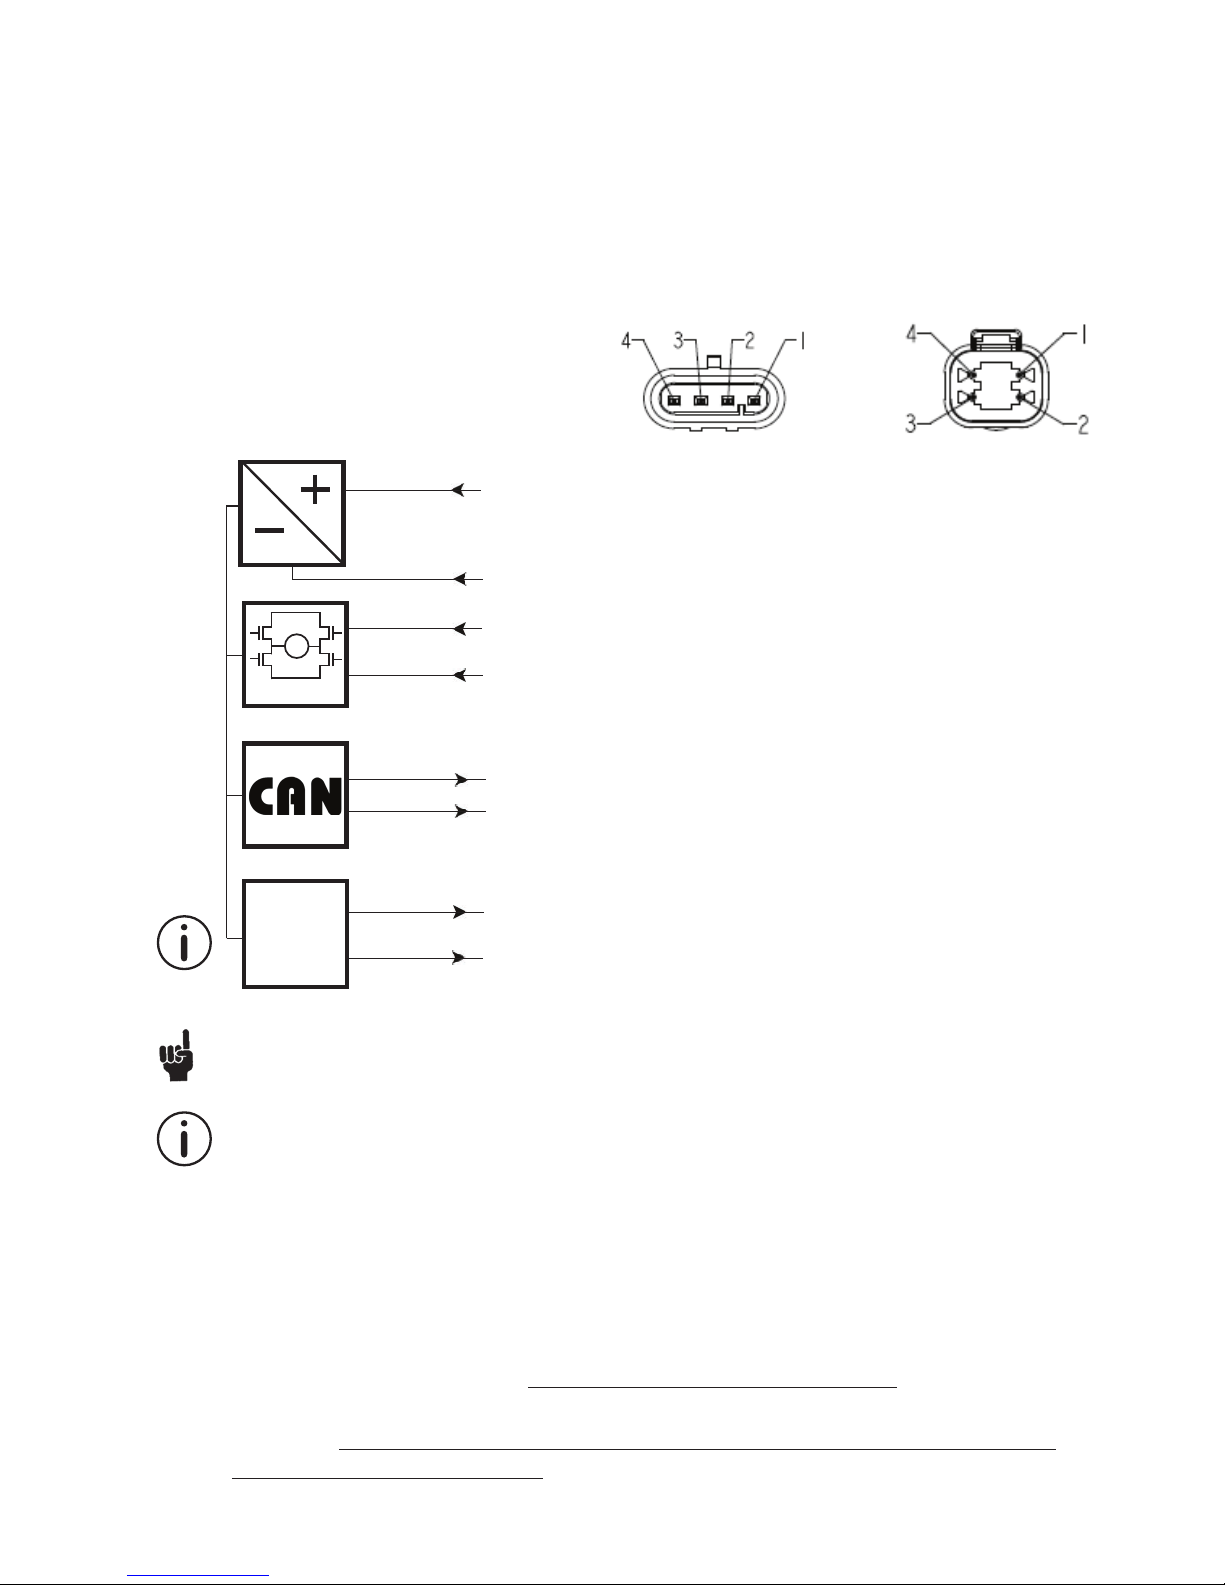
Actuator with CAN bus:
Connection diagram:
Fig. 12 : 25xxxxxxxxxx7x1x=xxxxx0xxxxxxx
Please be aware that if the power supply is not properly connected, you might damage the actuator!
CAN bus actuators are produced and delivered in the inner endstop position.
In case the customer needs the CAN bus actuators to be delivered in another endstop position,
this will be possible by generating a special item number.
The BusLink software tool (v2.0 or later versions) is available for CAN bus and can be used for:
Diagnostics, manual run and configuration.
BusLink LIN is only intended for BusLink service interface.
Download BusLink software here: http://www.linak.com/techline/?id3=2363
For more information and easy set-up of BusLink, please follow this link to view the Quick Guide
for BusLink: http://www.linak.com/corporate/pdf/ENGLISH/BROCHURE/TECHLINE_BusLink%20
Quick%20Guide_Brochure_Eng.pdf
BROWN
BLUE
YELLOW
GREEN
WHITE
VIOLET
BLACK
12/24V DC
RED
INWARDS
OUTWARDS
DATA
DATA GND
M
H-Bridge
Service
interface
CAN_H
CAN_L
Standard connector front view
DEUTSCH AMP
4P4P
22
11
33
44
Page 49
Page 49 of 76
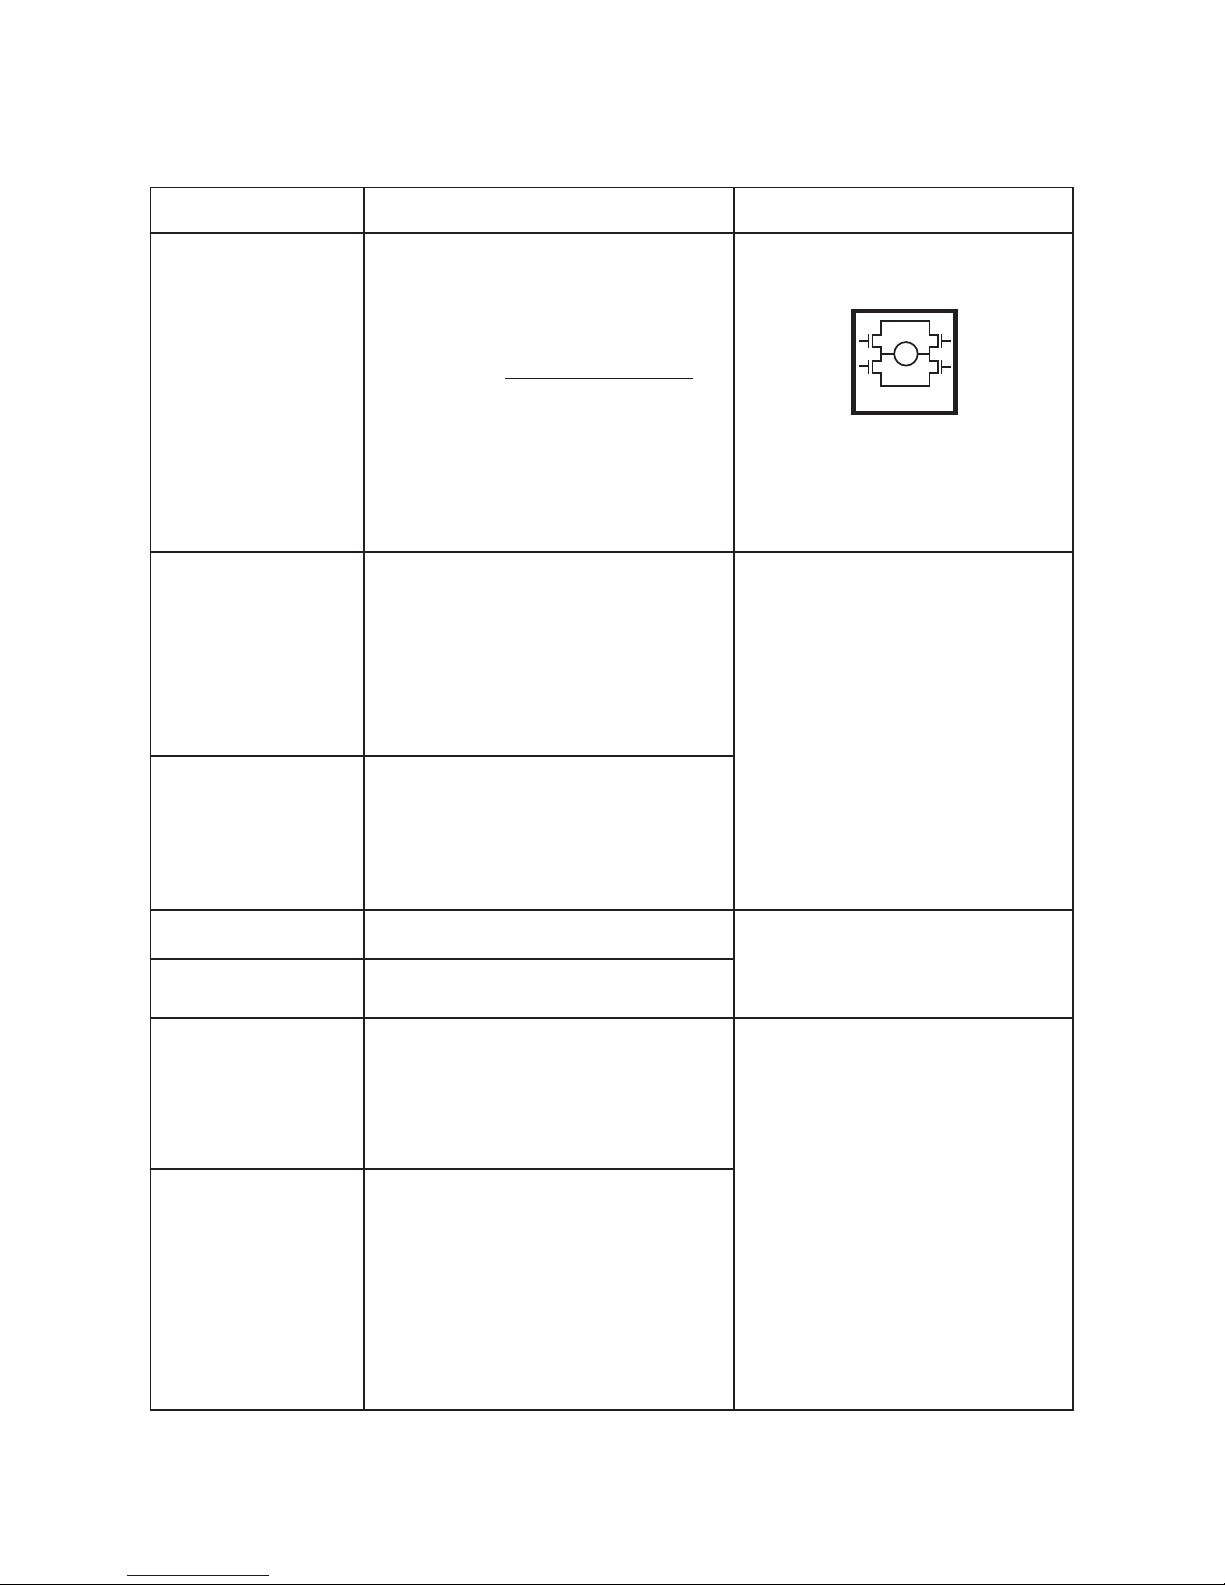
I/O specifications:
Actuator with CAN bus:
Input/Output Specification Comments
Description
Compatible with the SAE J1939 standard. Uses CAN messages to command
movement, setting parameters and to
deliver feedback from the actuator.
See the LINAK CAN bus user manual.
Actuator identification is provided,
using standard J1939 address claim or
fixed addresses.
See connection diagram,
fig. 12, page 56
Brown 12-24VDC + (VCC)
Connect Brown to positive
12V ± 20%
24V ± 10%
12V, current limit 8A
24V, current limit 5A
Note: Do not swap the power supply
polarity on the brown and blue
wires!
Power supply GND (-) is electrically
connected to the housing
Current limit levels can be adjusted
through BusLink
If the temperature drops below 0°C,
all current limits will automatically
increase to 9A for 12V and 6A for
24V.
Blue 12-24VDC - (GND)
Connect Blue to negative
Red Extends the actuator On/off voltages:
> 67% of V
IN
= ON
< 33% of V
IN
= OFF
Black Retracts the actuator
Green CAN_L LA25 with CAN bus does not
contain the 120Ω terminal resistor.
The physical layer is in accordance
with J1939-15.*
Speed: Baudrate: 250 kbps
Max bus length: 40 meters
Max stub length: 3 meters
Max node count: 10
(can be extended to 30 under
certain circumstances)
Wiring: Unshielded twisted pair
Cable impedance: 120 Ω (±10%)
Yellow CAN_H
M
H-Bridge
* J1939-15 refers to Twisted Pair and Shielded cables. The standard/default cables delivered with LA25 CAN
do not comply with this.
Page 50
Page 50 of 76
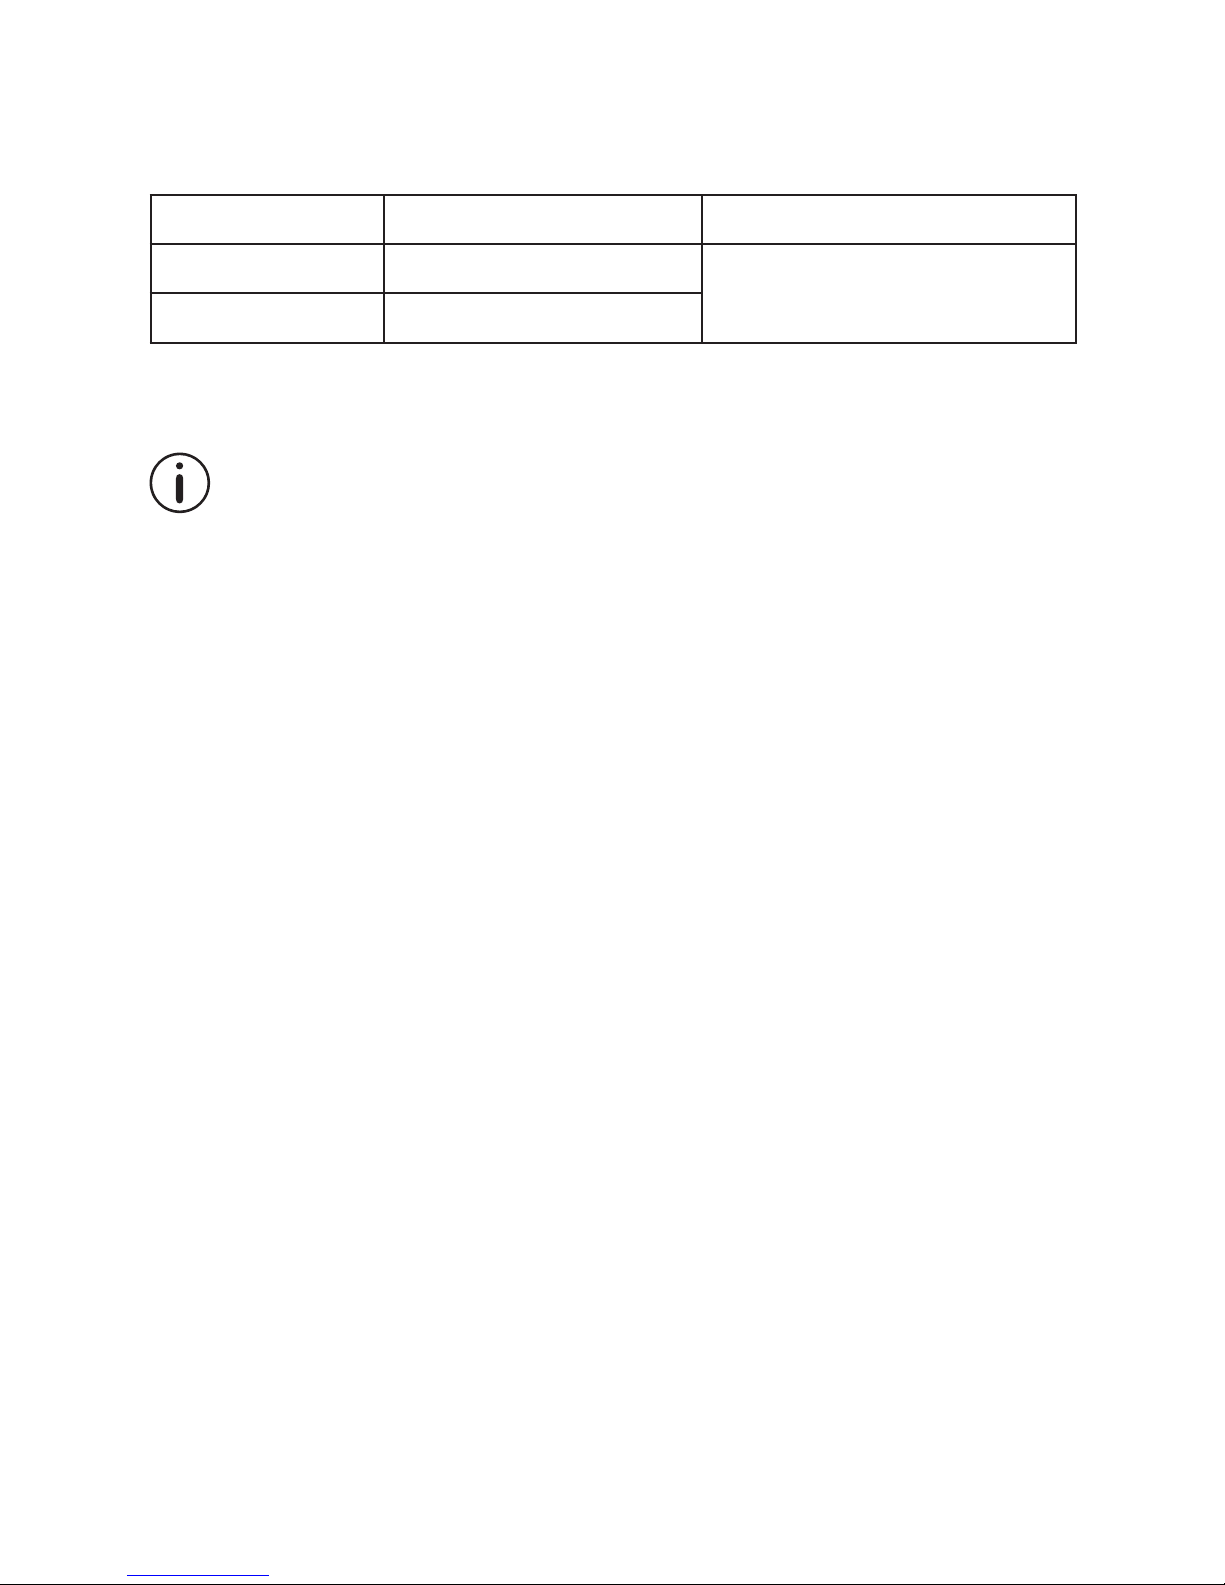
Input/Output Specification Comments
Violet Service interface
Only BusLink can be used as service
interface. Use green adapter cable
White Service interface GND
I/O specifications:
Actuator with CAN bus:
Please note that the BusLink cables must be purchased separately from the actuator!
For more information about the usage of CAN bus, please see the LINAK
TECHLINE CAN bus user manual.
Page 51
Page 51 of 76
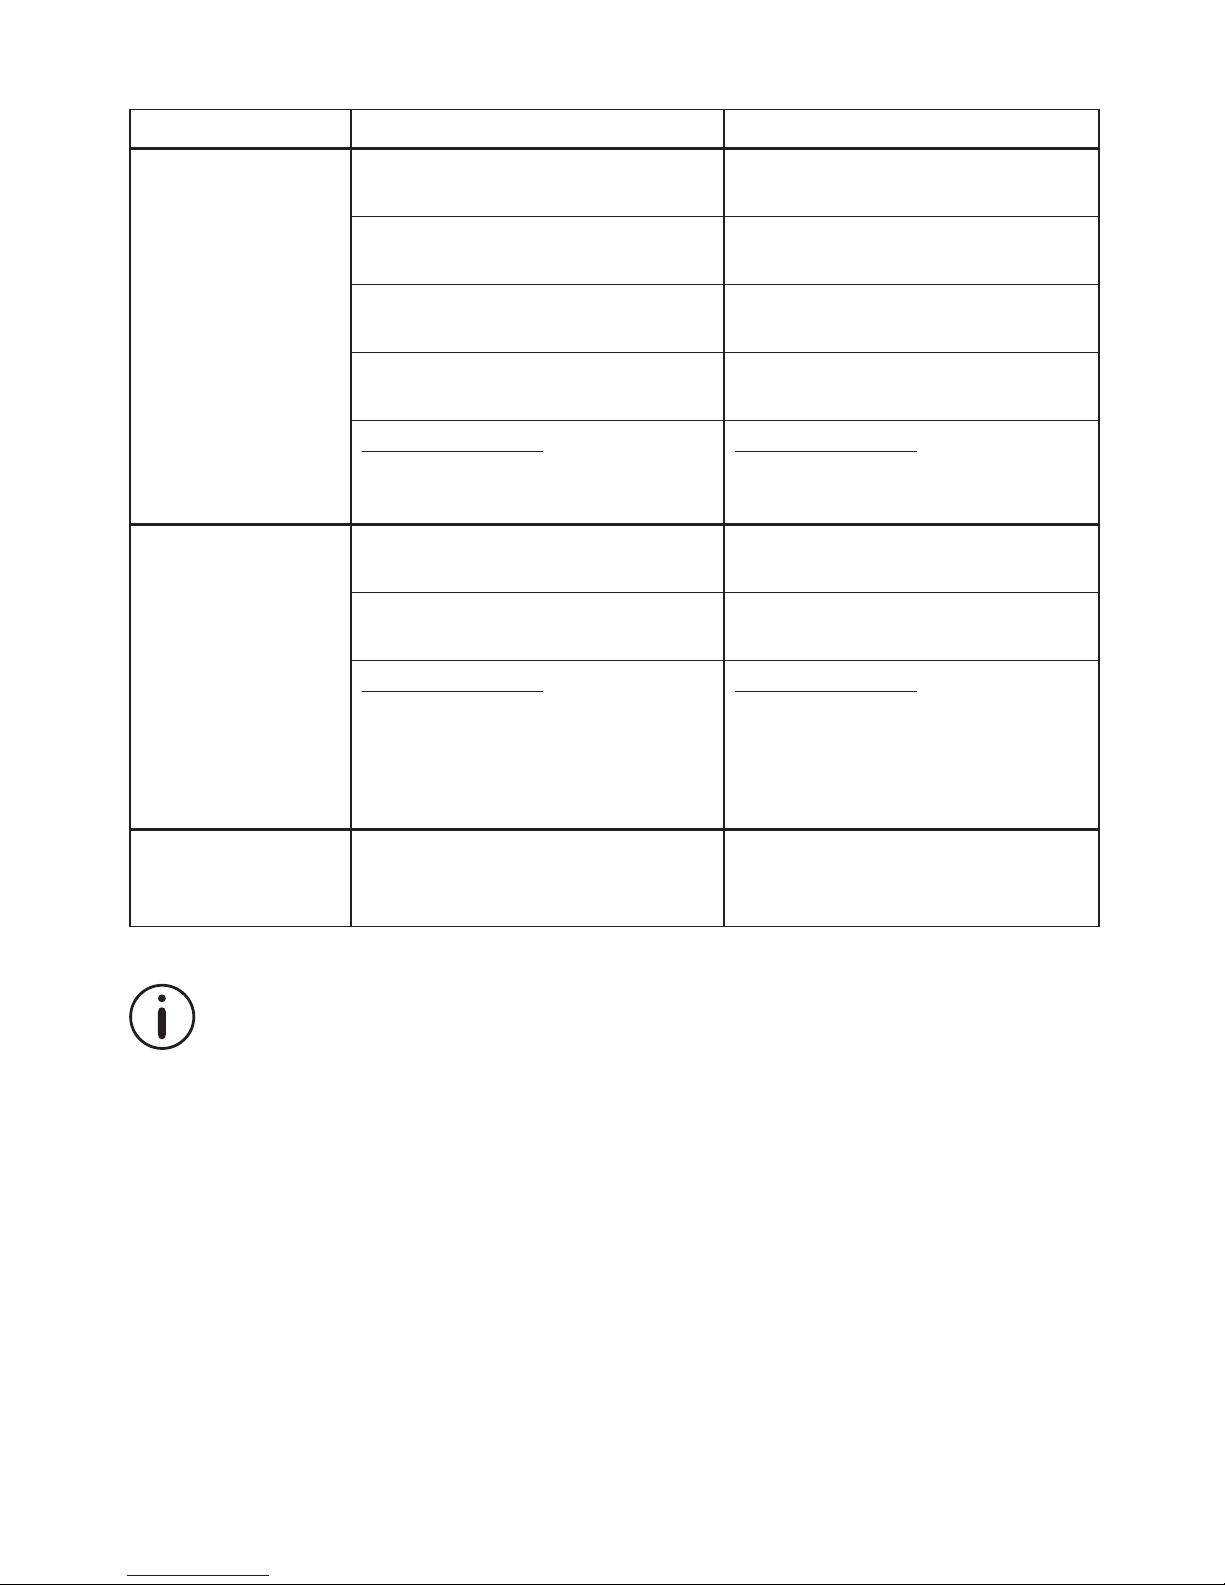
Chapter 3
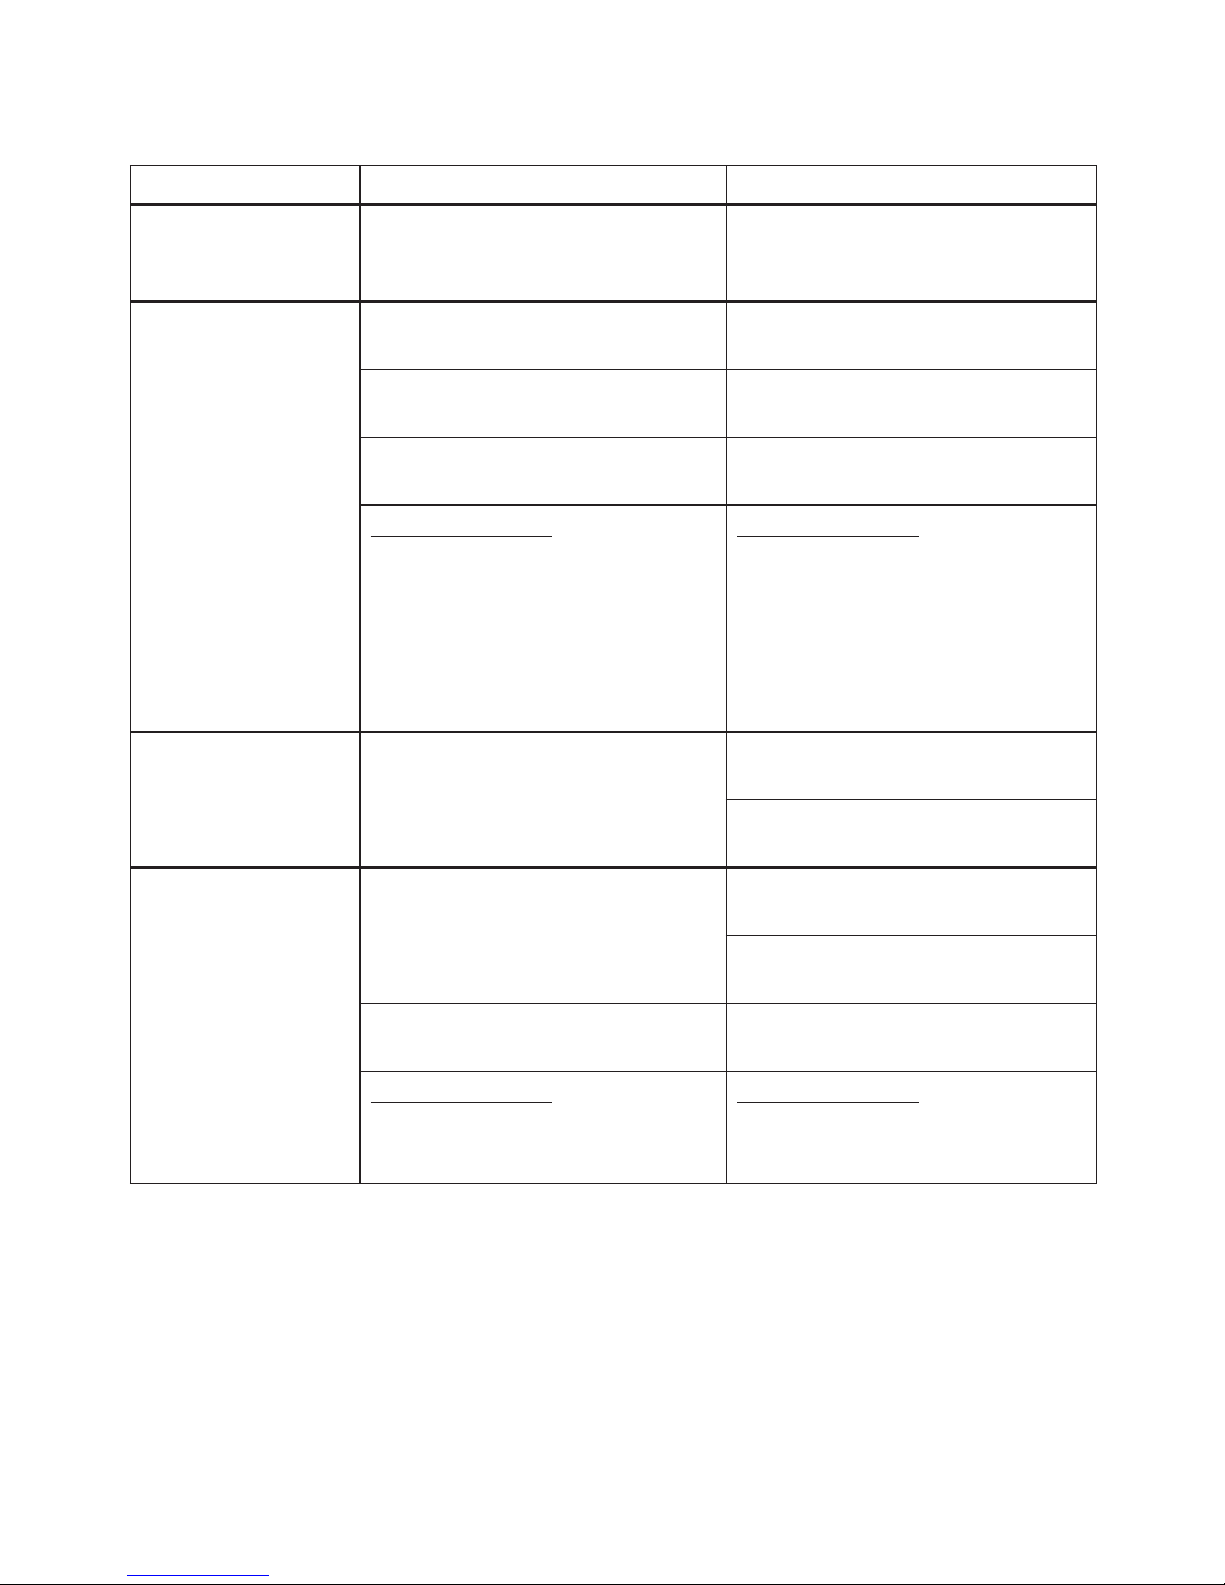
Troubleshooting
Symptom Possible cause Action
Motor runs but
spindle does not
move
Gearing system or spindle damaged Please contact LINAK
No motor sound or
movement of piston
rod
The actuator is not properly connected
to the power supply
Check the connection to the power
supply or the external control unit (if any)
Customer fuse burned Check the fuse
Cable damaged Change the cable
For IC Advanced only:
Wrongly connected
For IC Advanced only:
Please make sure that the power
supply polarity is properly
connected, otherwise you might
damage the actuator
Check the wire connection on the
internal control unit
Excessive power
consumption
Misalignment or overload in the
application
Align or reduce the load
Try to run the actuator without load
Actuator cannot lift
full load or motor
runs too slowly
Misalignment or overload in the
application
Align or reduce the load
Try to run the actuator without load
Insufficient power supply Check the power supply
For IC Advanced only:
Internal current limit reached
Actuator speed is too low
For IC Advanced only:
Connect the actuator to BusLink and
check the existing parameters
Page 52
Page 52 of 76
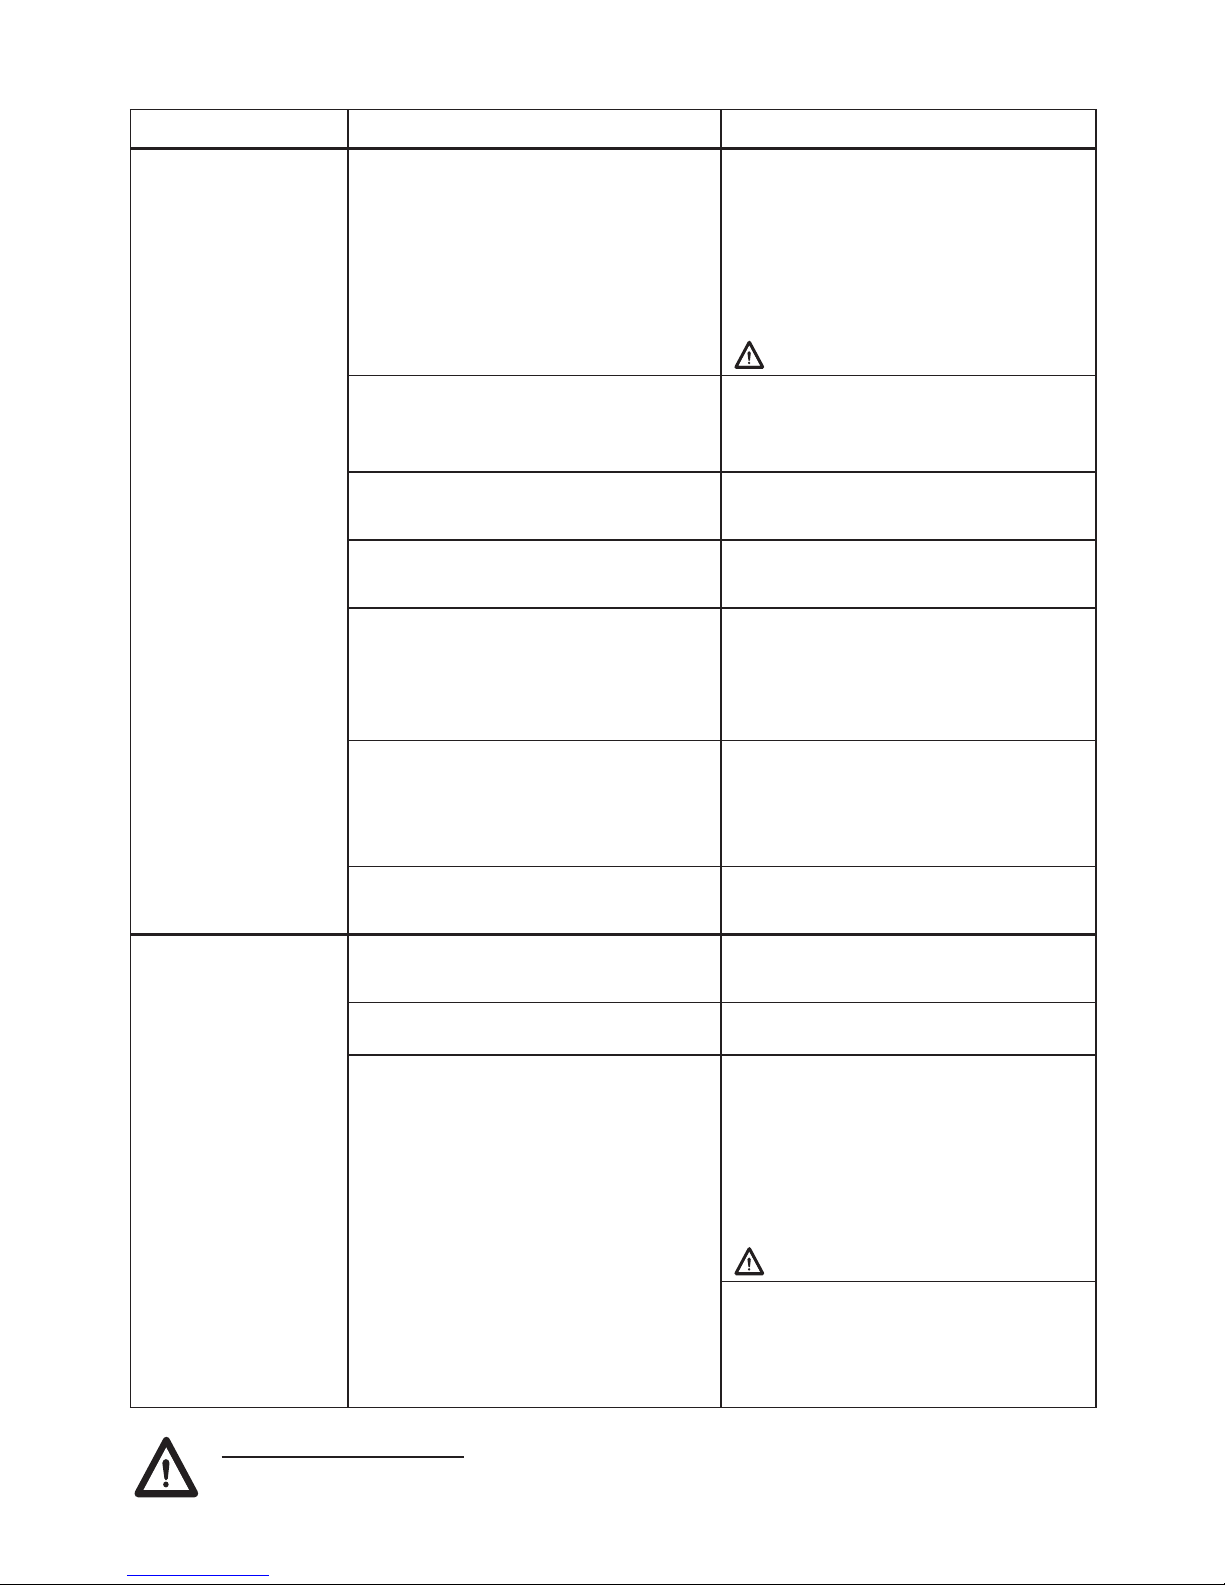
Troubleshooting
Symptom Possible cause Action
No signal or
incorrect feedback
output
Cable damaged Change the cable
Wrongly connected Check the wiring
Signal is constantly high/low Run the actuator to fully extended and
retracted positions
Feedback output overloaded Reduce the load according to your
chosen feedback type
For IC Advanced only:
Incorrect feedback output/level
For IC Advanced only:
Connect the actuator to BusLink and
check for correct feedback option
Actuator runs in
smaller steps
Insufficient power supply Check the power supply
Load is higher than specified Reduce the load
For IC Advanced only:
Internal safety procedure activated
For IC Advanced only:
Connect the actuator to BusLink and
check the following:
- Reason for last stop (page 53)
- Current cut-off levels in both directions
Actuator cannot
hold the chosen
load
Load is higher than specified Reduce the load
For further assistance, please contact your local LINAK supplier.
Page 53
Page 53 of 76
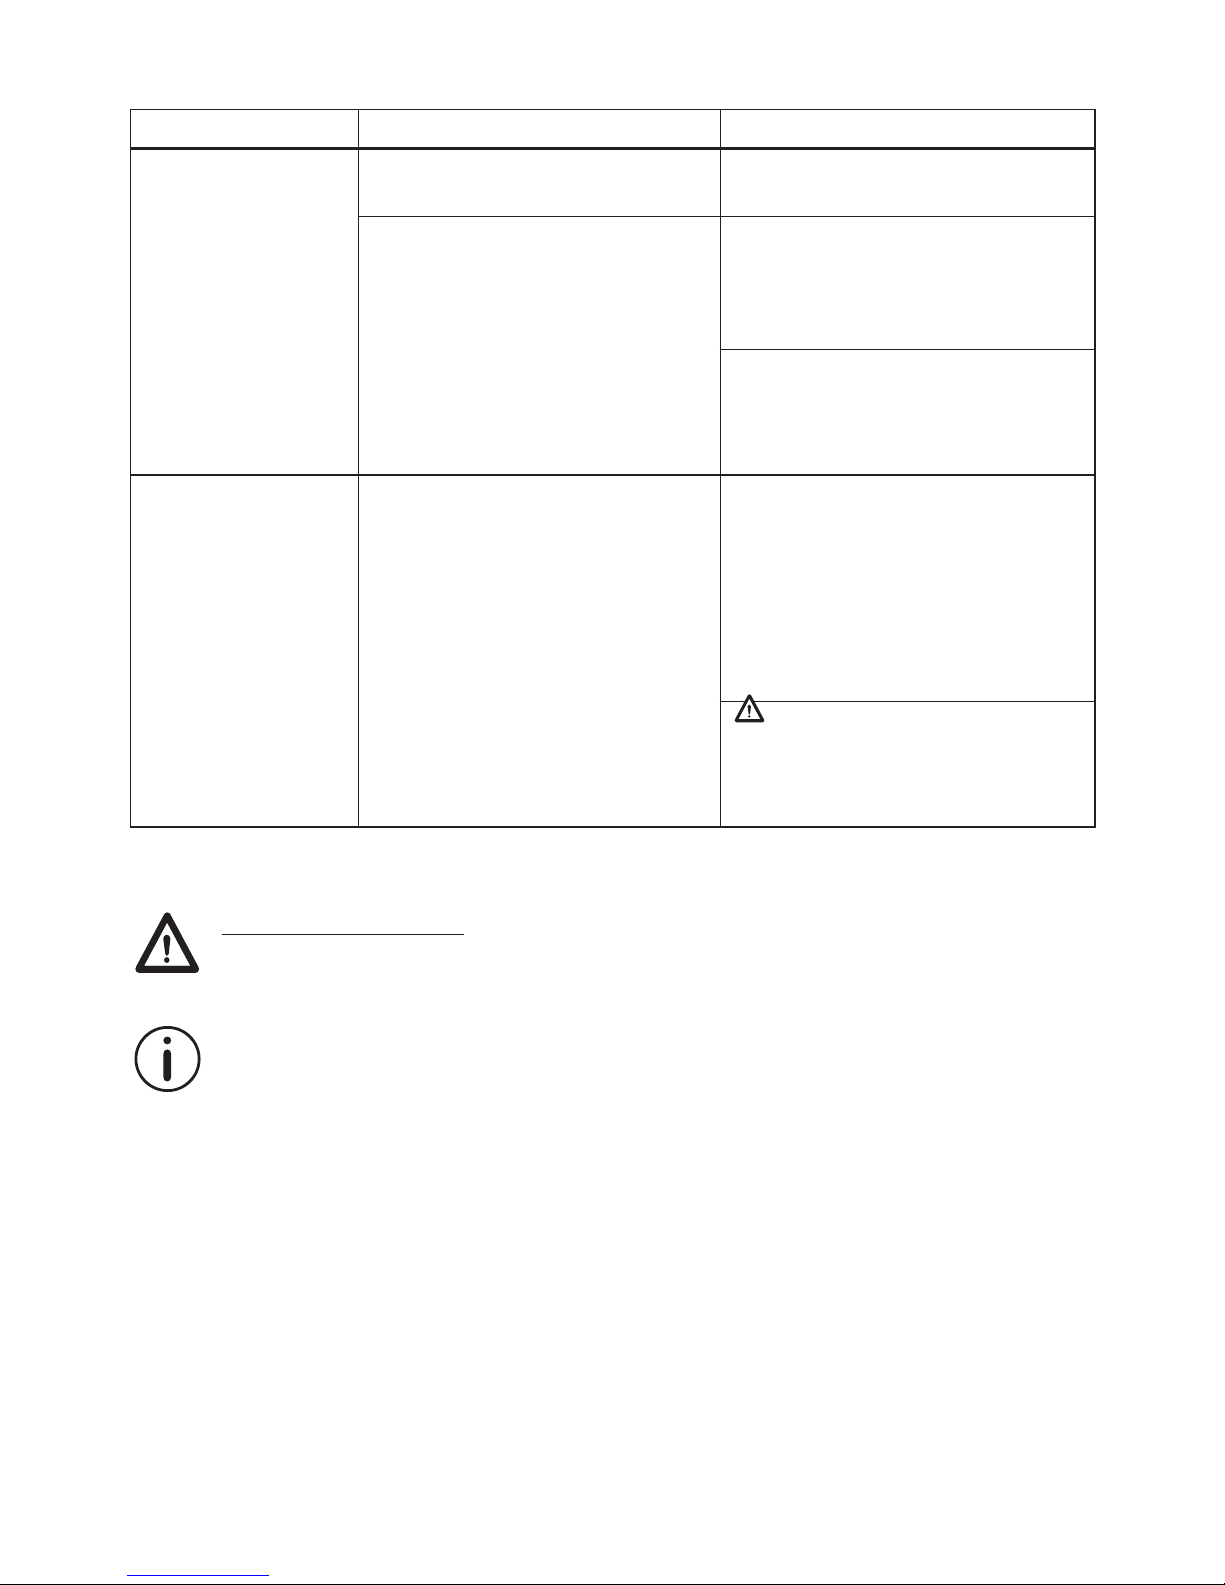
Troubleshooting for Parallel
Only for Non-critical Parallel:
Even if all actuators are not connected, the connected actuators will run after re-powering.
More information on page 46
Symptom Possible cause Action
Actuators do not
move
The actuators are not properly
connected to the power supply
Check the connection to the power
supply or the external control unit (if any)
Please make sure that the power
supply polarity is properly
connected, otherwise you might
damage the actuator
Please see non-critical info below
Wrong number of actuators in the
system
Check if the number of actuators in
the system match the number that was
ordered
Communication wires are not properly
connected
Check the parallel communication wires
for all actuators
Signals run in/run out are not properly
connected
Check the wire connection on the
internal control unit
Position lost Disconnect all cables, connect the
actuator(s) to BusLink one at a time and
check the following:
- Reason for last stop (page 53)
After everything is connected, put power
on all actuators at the same time. Then
wait 10 seconds before the Run In/Run
Out signals are activated
If this does not work, initiate the Parallel
manual service mode (page 48)
Actuators cannot
lift full load
Insufficient power supply Check the power supply while the
actuator is running
Overload in application Reduce the load
Connect actuator(s) to BusLink one at a
time and check the following:
- Type of chosen Parallel system
- Reason for last stop (page 53)
- Current cut-off levels in both
directions
Please see non-critical info below
After everything is connected, put power
on all actuators at the same time. Then
wait 10 seconds before the Run In/Run
Out signals are activated
Page 54
Page 54 of 76
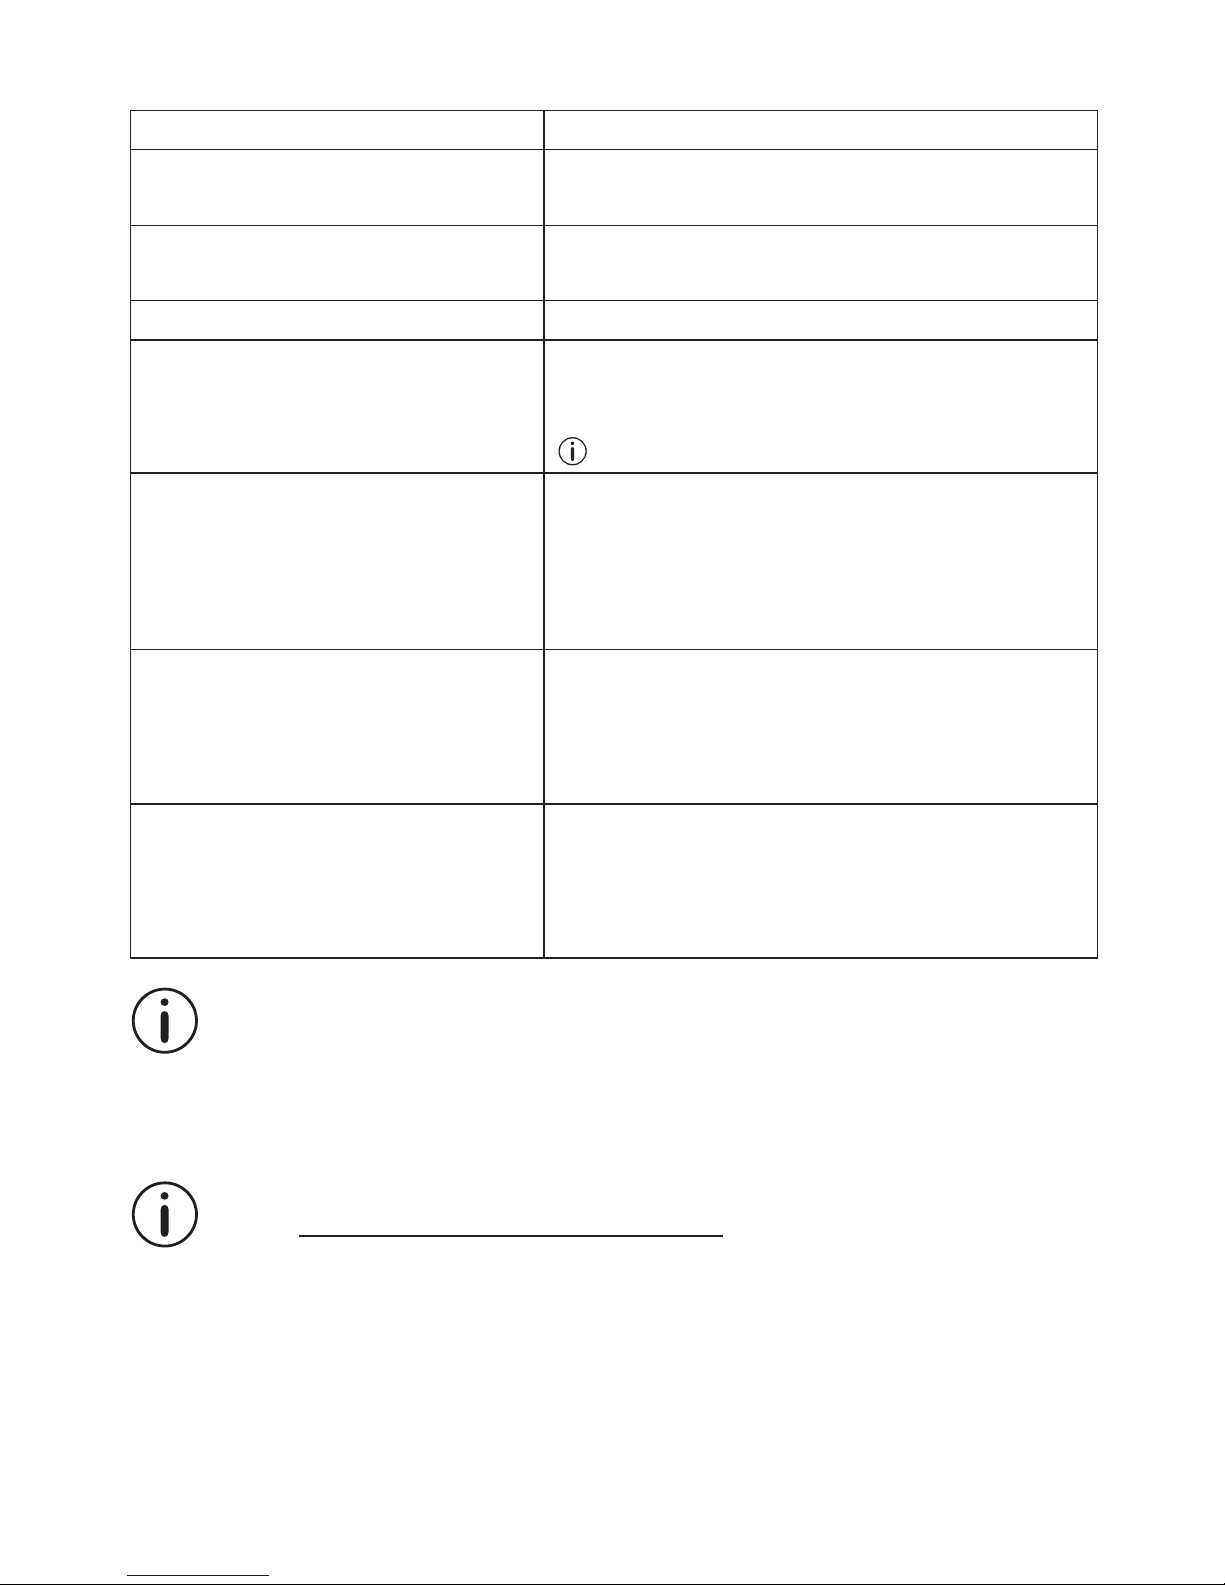
Troubleshooting for Parallel
For further assistance, please contact your local LINAK supplier
Only for Non-critical Parallel:
Even if all actuators are not connected, the connected actuators will run after re-powering.
More information on page 46
Symptom Possible cause Action
Actuators run in
smaller steps before
stop
Insufficient power supply Check the power supply while the
actuator is running
Connect the actuator(s) to BusLink one
at a time and check the following:
- Reason for last stop (page 53)
- Current cut-off levels in both directions
After everything is connected, put power
on all actuators at the same time. Then
wait 10 seconds before the Run In/Run
Out signals are activated
Signal cable
damaged or
removed under
operation
All actuators stop at the same position The signal and power cables MUST be
re-connected to all actuators.
Ensure that no actuator is missing
in the system. Otherwise, the
system will not work, not even
after re-powering
Please see non-critical info below
After everything is connected, put power
on all actuators at the same time. Then
wait 10 seconds before the Run In/Run
Out signals are activated
Page 55
Page 55 of 76
For more information and easy set-up of BusLink, please follow this link to view the Quick Guide for
BusLink: http://www.linak.com/techline/?id3=2356
Initialisation procedure:
To initialise the actuator(s), move each actuator into fully extended and fully retracted position.
Either initialise the actuators one at a time through BusLink, or use the Parallel manual service mode
(see page 48).
In case the initialisation does not solve the issue, please contact your local LINAK supplier
BusLink service counter - Reason for last stop
Possible cause Action/Info
H-bridge error
Internal SMPS error
• Please contact your local LINAK supplier for further
instructions
Overcurrent • The actuator(s) cannot continue in the same direction
• Reactivation is needed in the opposite direction
EOS error • Please contact your local LINAK supplier
Hall error • The actuator(s) stop. When seeing hall error, the actuator
goes into ‘position lost’, and the whole system will need
initialisation
Find more info on the initialisation procedure below
Out of range temperature for ambient
location
Out of range temperature at FET location
The above can be due to high environment
temperature or high duty cycle
• The error causes the actuator(s) to stop. After elimination
of the error (cooling down) and reactivation of the
movement, the actuator(s) will move normally
• This may not be used for stopping the actuator(s)
Overvoltage • When detecting overvoltage, the actuator(s) stop. The
actuator(s) remain stopped until the error condition is
removed. To remove the error condition, the voltage level
must be below 38V and the Run In/Run Out signals must be
removed before the next movement
Undervoltage • When detecting undervoltage, the actuator(s) stop. The
actuator(s) remain stopped until the error condition is
removed. To remove the error condition, the voltage level
must be above 8V and the Run In/Run Out signals must be
removed before the next movement
Page 56
Page 56 of 76
Specifications
Motor: Permanent magnet motor 12 or 24V
Cable: Motor: 8 x 18 AWG PVC cable
Housing: The housing is made of casted aluminium, coated for outdoor use and in harsh
conditions
Spindle part: Outer tube: Extruded aluminium anodised
Inner tube: Stainless steel AISI304/SS2333
Acme spindle: Trapezoidal spindle with high efficiency
Temperature range: - 40
o
C to +85o C For IECEx/ATEX: - 25o C to +65o C
- 40o F to +185o F - 13o F to +149o F
Full performance +5o C to +40o C
End play: 2 mm maximum
Weather protection: Rated IP66 for outdoor use. Furthermore, the actuator can be washed down
with a high-pressure cleaner (IP69K)
Compatibility: The LA25 IC is compatible with SMPS-T160 (For combination possibilities, please
see the User Manual for SMPS-T160)
Usage:
• Duty cycle is max. 20% (4 min. drive and 16 min. rest)
The duty cycles are valid for operation within an ambient temperature of +5°C to +40°C
• Storage temperature: -55°C to + 105°C
• Noise level: With standard motor: Max. 58.5 dB (A)
Measuring method DS/EN ISO 3743-1 actuator not loaded
• Safety device regarding functional failure:
Safety nut
The LA25 has a built-in safety nut in push as an option.
Actuators with a safety nut in push can only function when used in push applications. The safety nut
comes into operation should the main nut fail. Afterwards, it is only possible to drive the actuator into the
innermost position. Then, the actuator will not function anymore and it must be sent for service. The same
functionality, but in the opposite direction, goes for actuators with a safety nut in pull
Mechanical endstop
LA25 is equipped with mechanical endstop
Chapter 4
Page 57
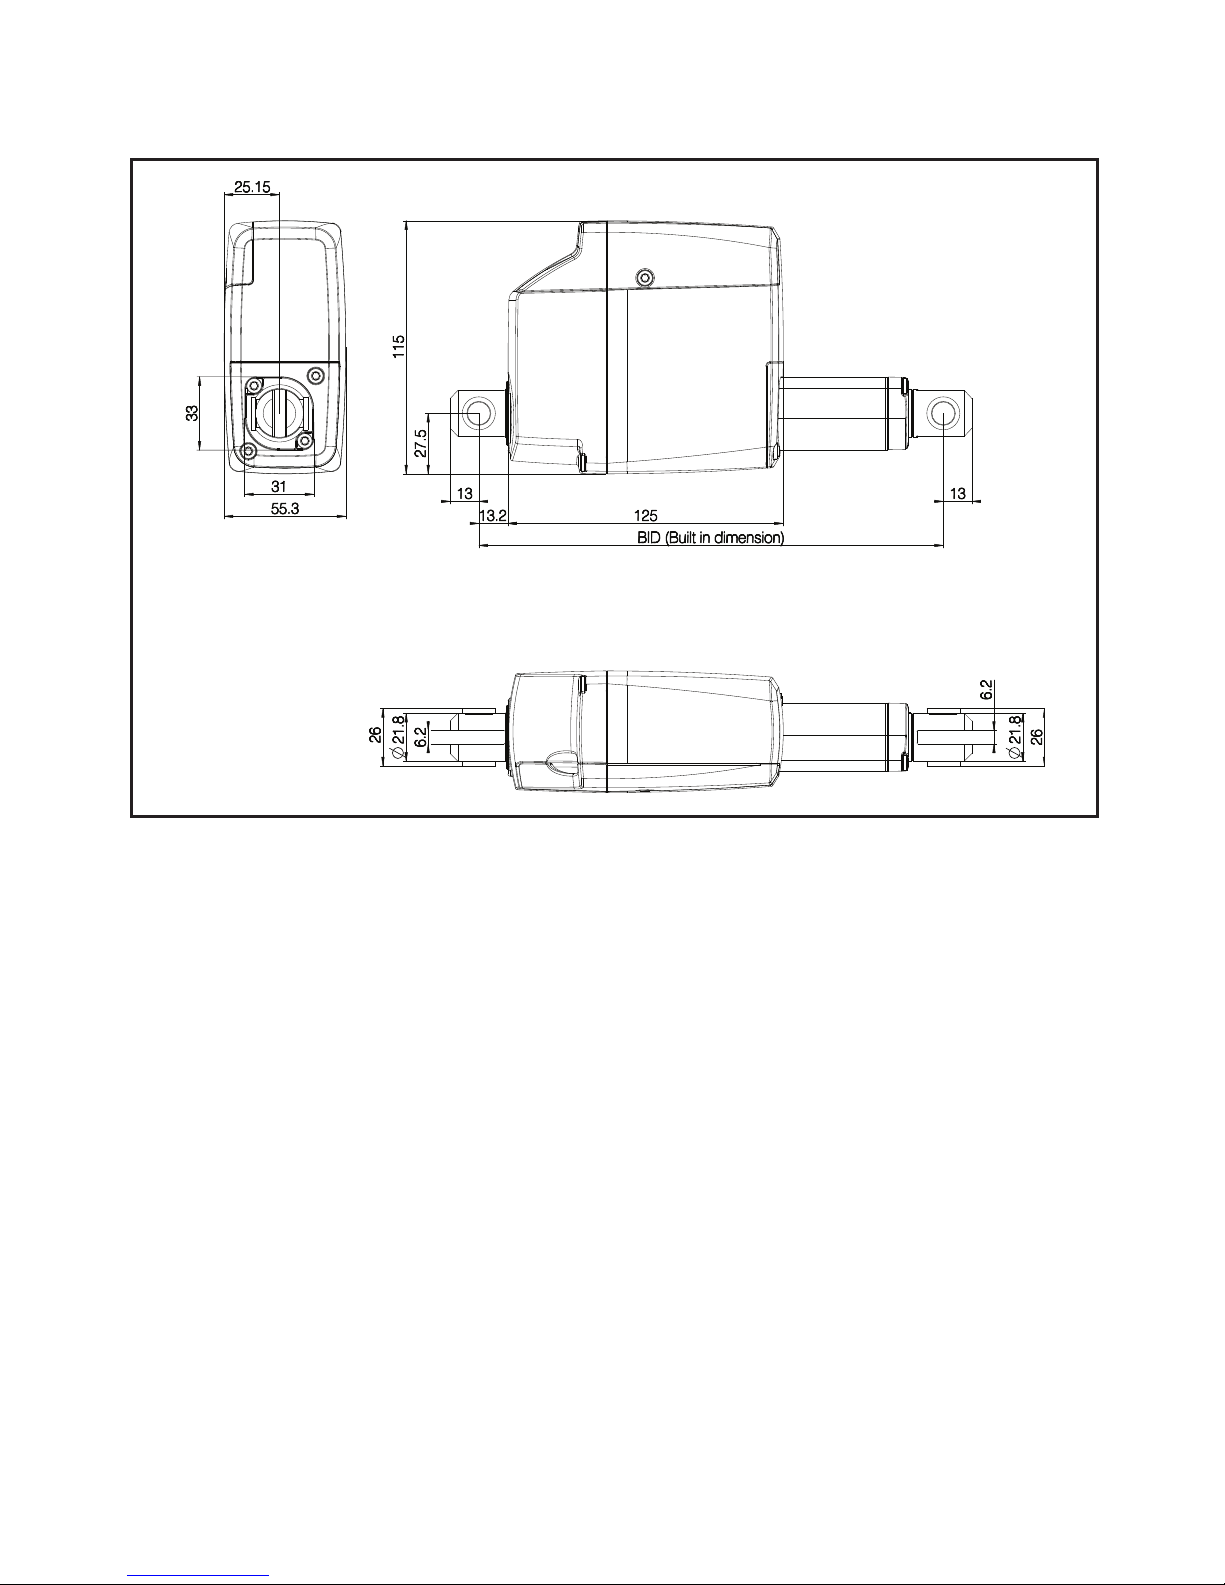
Page 57 of 76
TECHLINE® LA25:
Actuator dimensions
Page 58
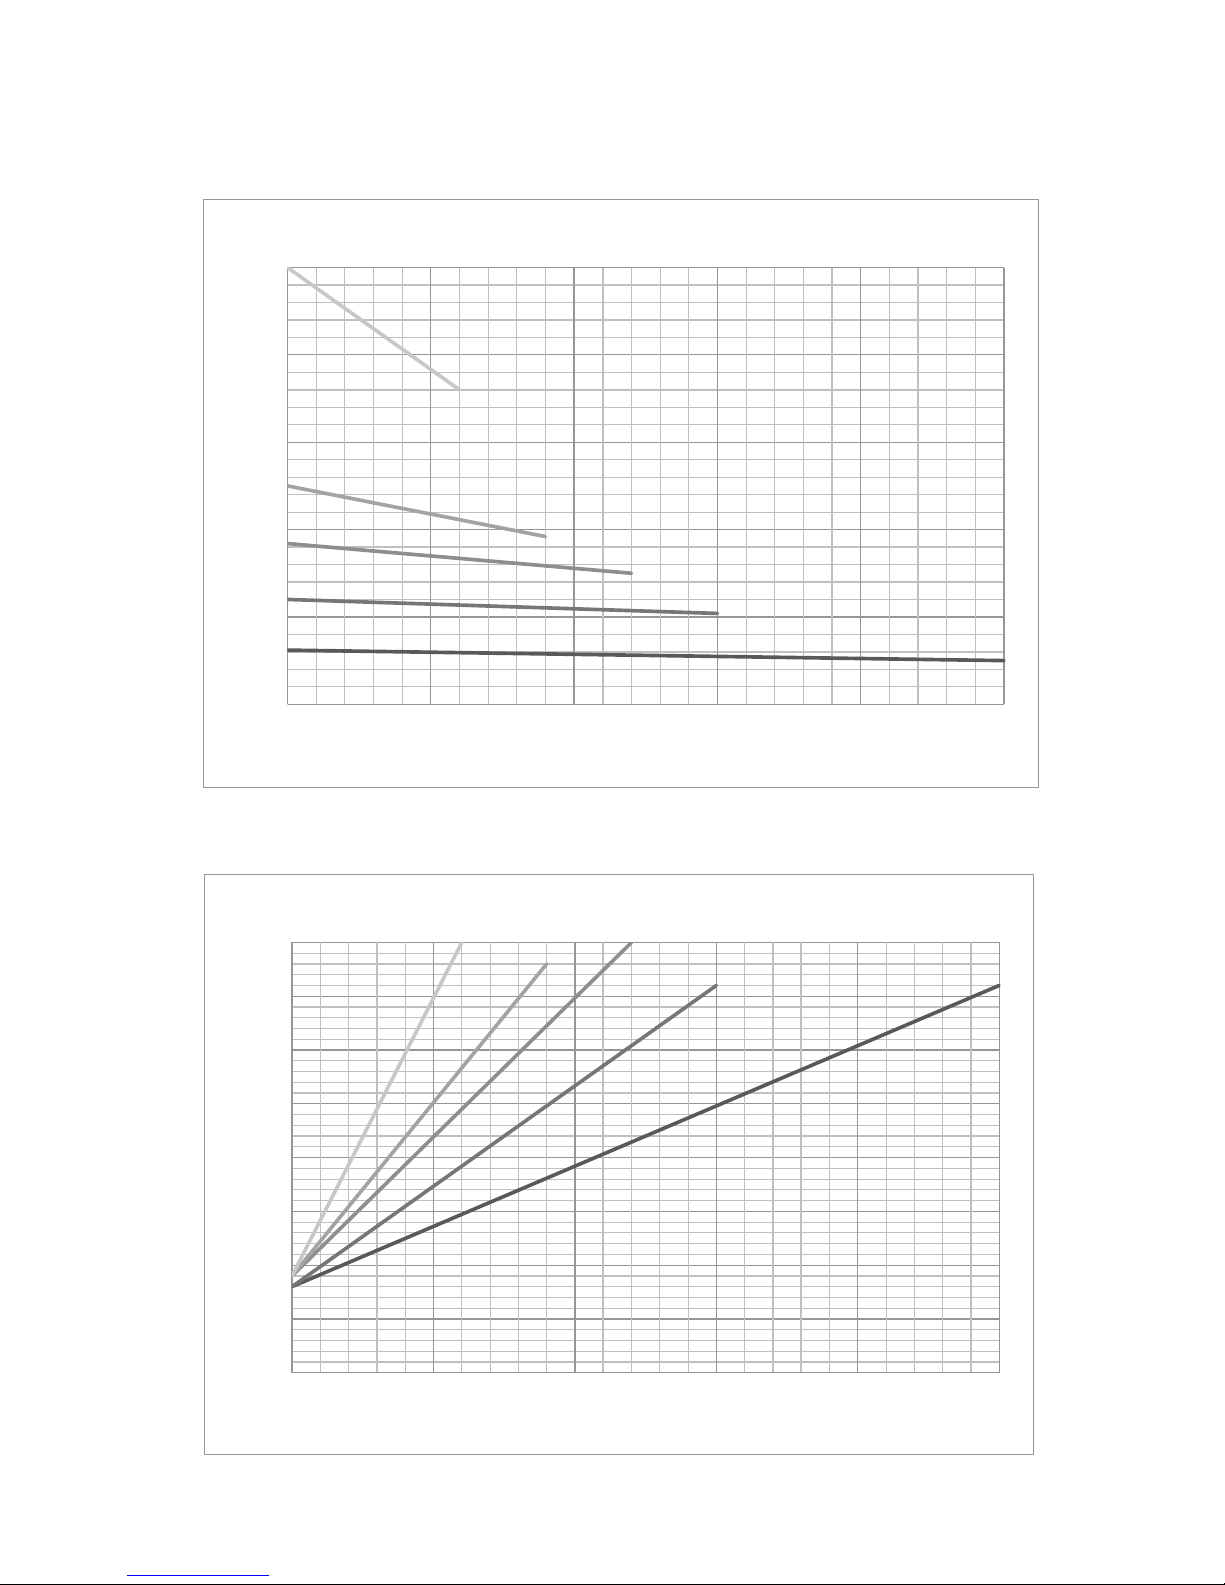
Page 58 of 76
Speed and current curves - 12V motor
The values below are typical values and made with a stable power supply and an ambient temperature of 20˚ C.
0
5
10
15
20
25
0 500 1000 1500 2000 2500
Speed [mm/s]
Thrust [N]
LA25 - 12V Speed vs Thrust
12mm pitch
3mm pitch
6mm pitch
9mm pitch
20mm pitch
0
0,5
1
1,5
2
2,5
3
3,5
4
0 500 1000 1500 2000 2500
Current [A]
Thrust [N]
LA25 - 12V Current vs Thrust
3mm pitch
6mm pitch
9mm pitch
12mm pitch
20mm pitch
Page 59
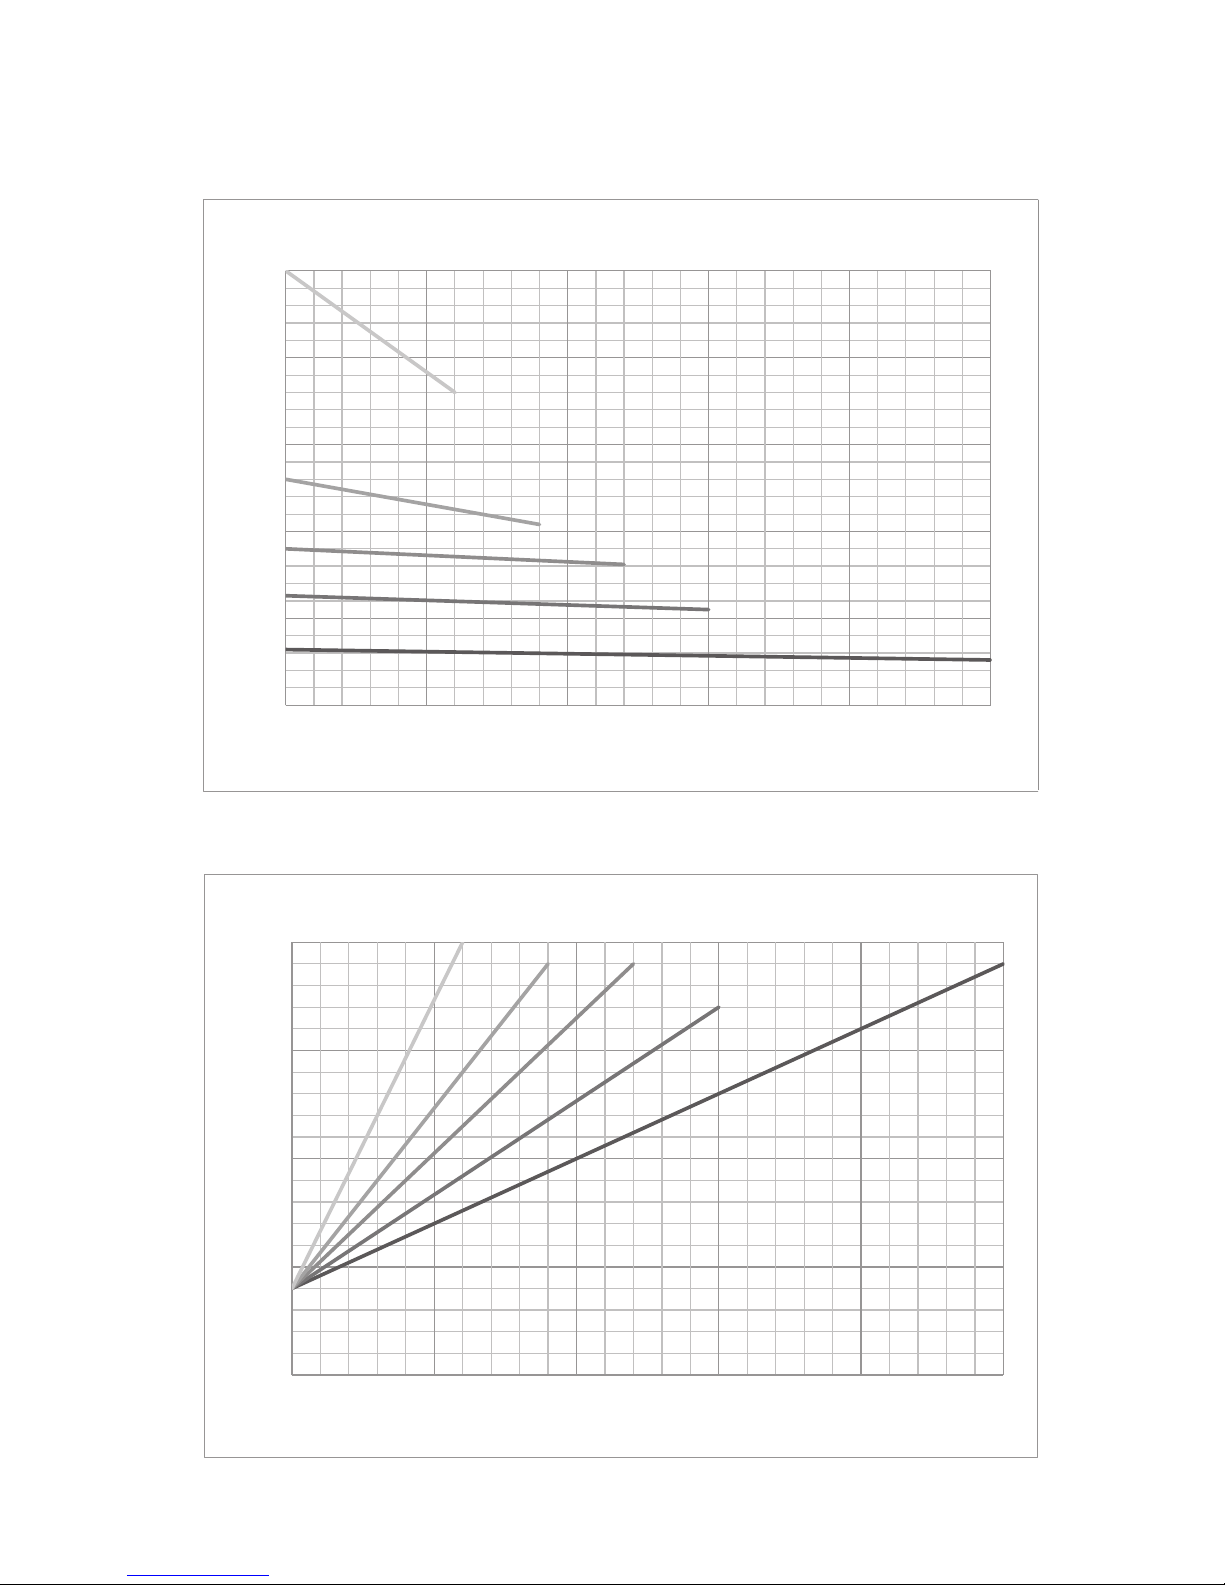
Page 59 of 76
Speed and current curves - 24V motor
The values below are typical values and made with a stable power supply and an ambient temperature of 20˚ C.
0
0,5
1
1,5
2
0 500 1000 1500 2000 2500
Current [A]
Thrust [N]
LA25 - 24V Current vs Thrust
20mm pitch
12mm pitch
9mm pitch
6mm pitch
3mm pitch
0
5
10
15
20
25
0 500 1000 1500 2000 2500
Speed [mm/s]
Thrust [N]
LA25 - 24V Speed vs Thrust
3mm pitch
6 mm pitch
9 mm pitch
12mm pitch
20 mm pitch
3mm pitch
6mm pitch
9mm pitch
12mm pitch
20mm pitch
Page 60
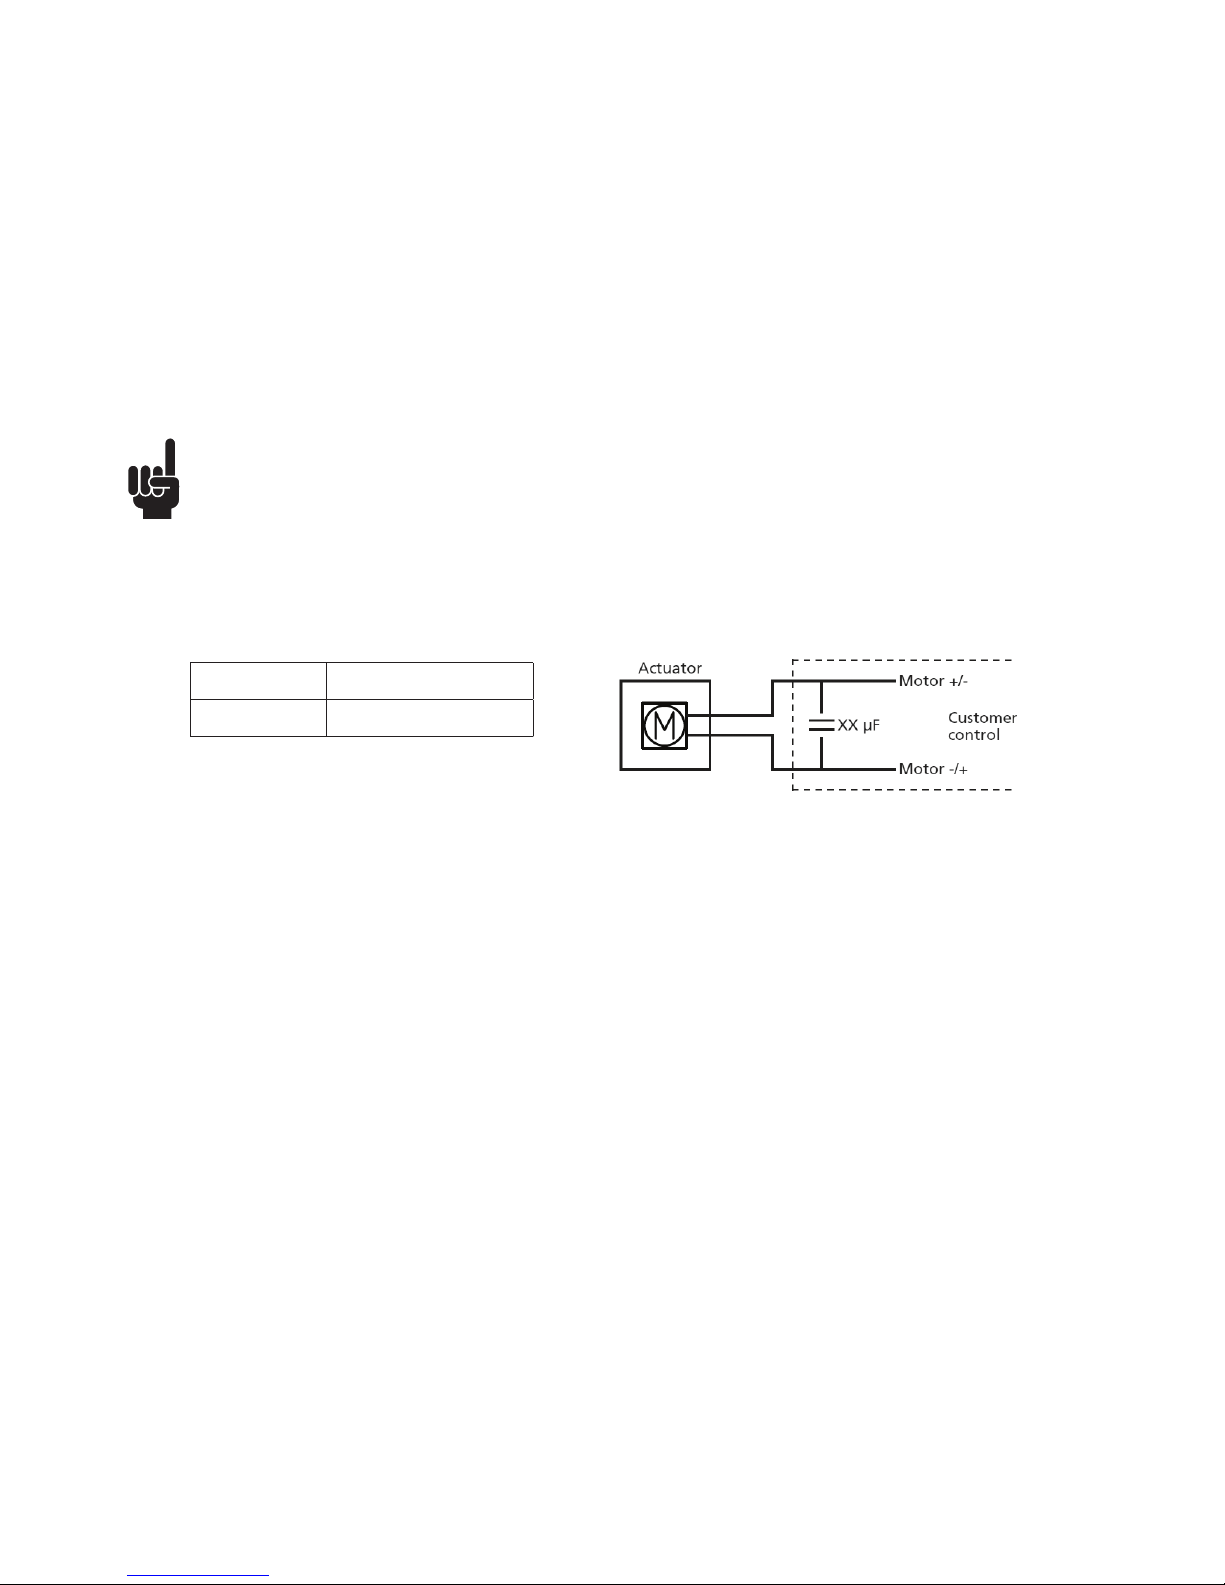
Page 60 of 76
Product Capacitor value
LA25 1 µF
Test of conducted and radiated emission (EMC)
All TECHLINE actuators have been tested in accordance with EN55011 class B (2007) (CISPR 11).
A 1m cable has been used in the test set-up.
Actuator without H-bridge
1) For normal operation the following is valid:
• Radiated emission requirements are met.
• Conducted emission requirements are met. However, to meet with these requirements a capacitor has been
mounted across the motor wires outside the actuator, and tests have then been made with this capacitor.
Capacitor values for some of the TECHLINE actuators can be found in the scheme below.
To comply with EN55011 class B (2007) a capacitor must be added across the motor wires, or the
connected control box must have similar/better filtering. The actuator is not delivered with a built in
capacitor, because then it would not be possible to PWM the motor for those who would want to do
that.
Please view the scheme below for the correct choice of capacitor for the actuator in question.
2) For systems/operations that use PWM-control it is up to the customer to test and meet the requirements.
Actuator with H-bridge
1) For normal operation with soft start/stop the following is valid:
• The actuator has been tested when operating with constant 80%-PWM.
• Radiated emission requirements are met.
• Conducted emission requirements are met.
2) For systems with LINAK PWM regulation (among other things parallel operation and speed regulation) the
following is valid:
• Radiated emission requirements are met.
• Conducted emission requirements are met.
3) Speed regulation:
• If the speed is regulated below a nominal speed of 80% (80%-PWM), it is necessary to mount a filter in order
to comply with the conducted emission requirements. For systems/operations that are speed regulated, it is up
to the customer to test and meet the requirements.
Page 61
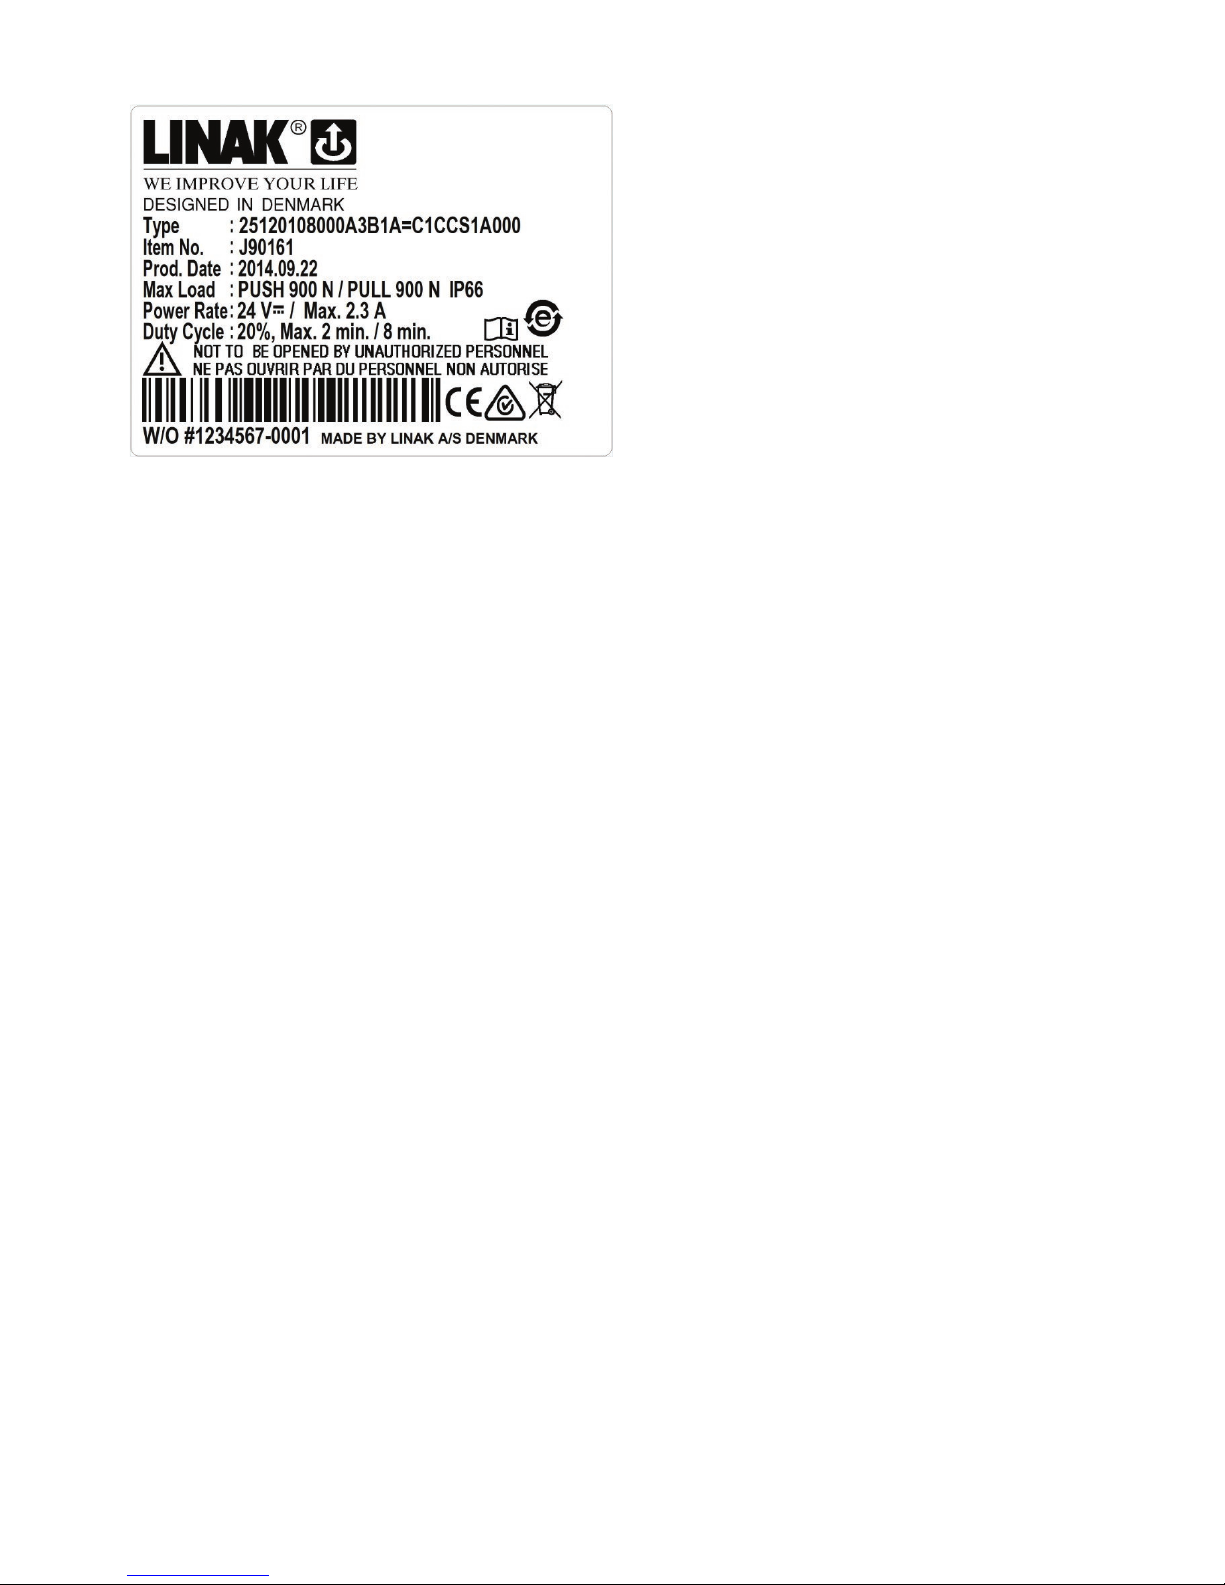
Page 61 of 76
Label for LA25
4. Max Load: Push 900N / Pull 900N IP66
Describes the maximum load that the product can be exposed to in compression and tension.
This line also contains a reference to the product’s IP protection degree
5. Power Rate: 24VDC / Max. 2.3 Amp
Input voltage for the product and maximum current consumption
6. Duty Cycle: 20%, Max. 2 min. / 8 min.
The duty cycle defines the maximum period during operation without interruption. After operation, a pause
must be observed. It is important that the operator follows the instructions of the duty cycle; otherwise, a
possible overload may result in reduced product life/errors
7. W/O# 1234567-0001
The LINAK work order followed by a unique sequential identification number
1. Type: 25120108000A3B1A=C1CCS1A000
Describes the basic functionality of the product
2. Item no.: J90161
Sales and ordering code
3. Prod. Date: YYYY.MM.DD
Production date describes when the product
has been produced. This date is the reference
for warranty claims
Page 62
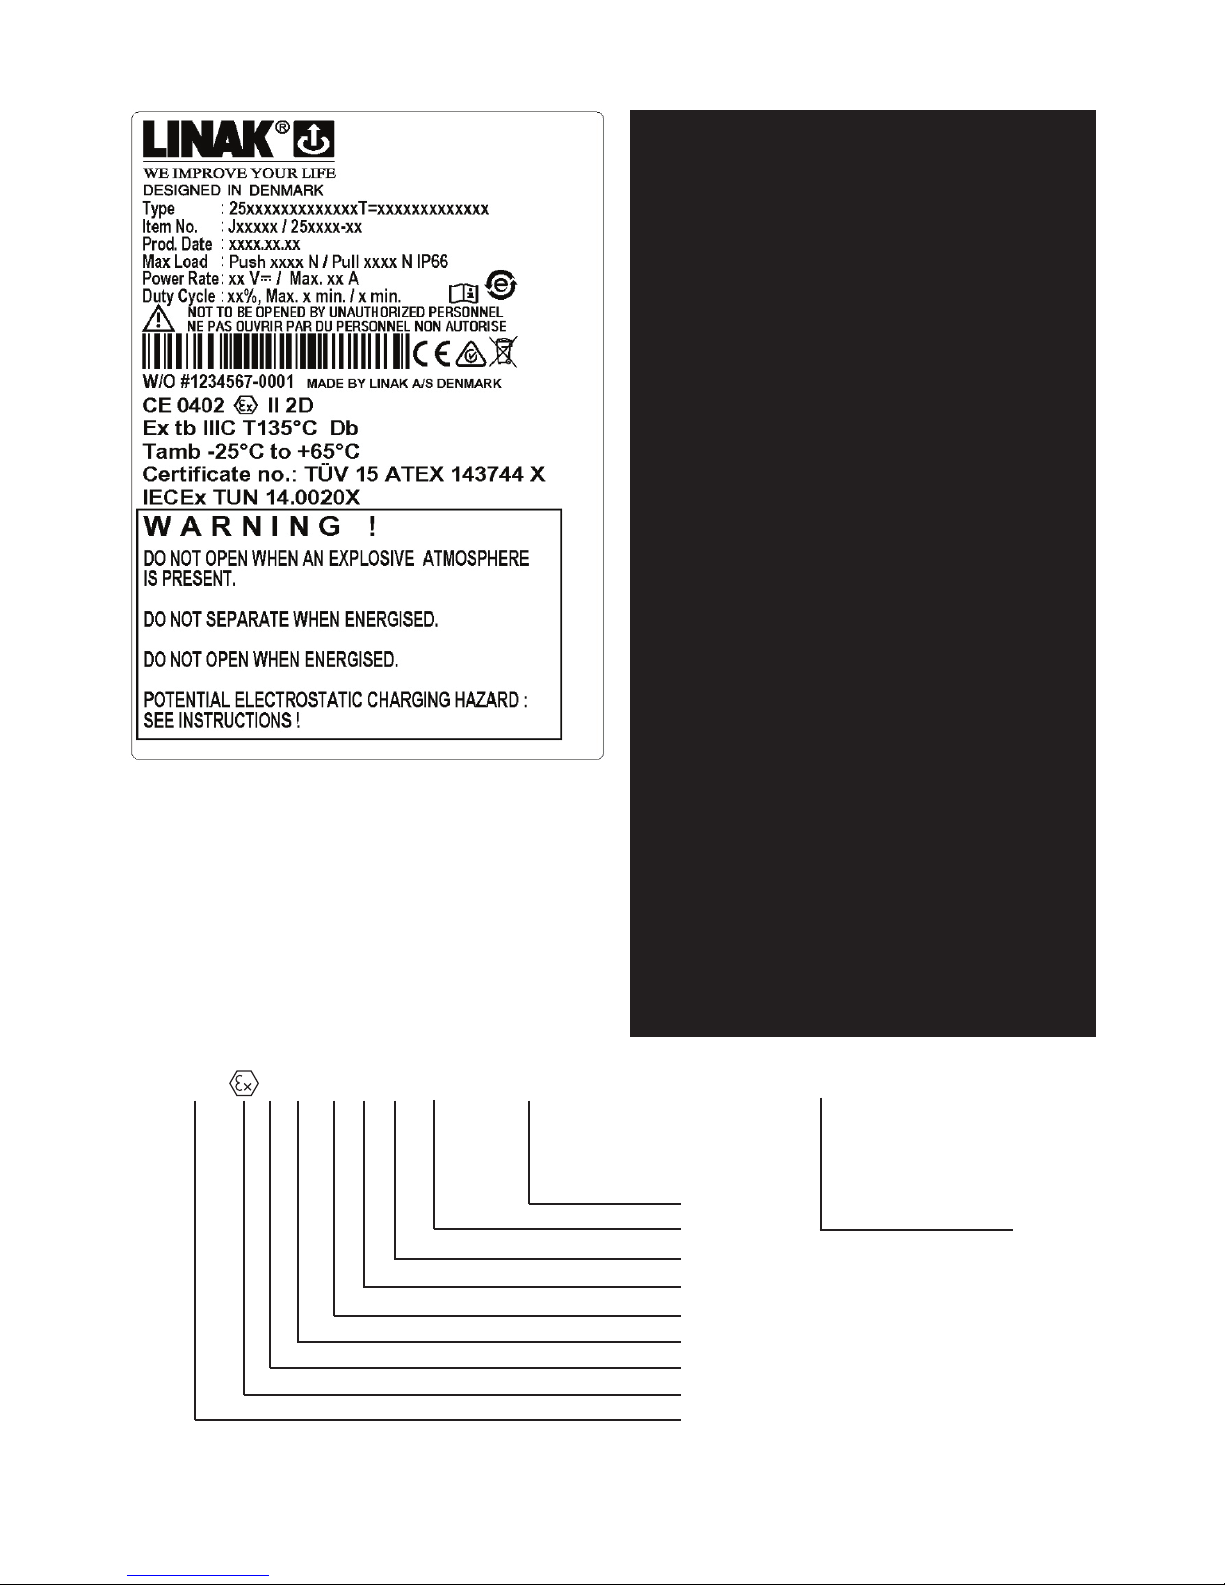
Page 62 of 76
Label for LA25 IECEx/ATEX
1. Type: 25xxxxxxxxxxxxxT+xxxxxxxxxxxxx
Describes the basic functionality of the product
2. Item no.: 25xxxx-xx
Sales and ordering code
3. Prod. Date.: YYYY.MM.DD
Production date describes when the product has
been produced. This date is the reference for
warranty claims
4. Max Load.: Push xxxx N / Pull xxxxN IP66
Describes the maximum load that the product
can be exposed to in compression and tension.
This line also contains a reference to the
product’s IP protection degree
5. Power Rate.: XX V / Max. xx Amp
Input voltage for the product and maximum
current consumption
6. Duty Cycle.:
The duty cycle defines the maximum period
during operation without interruption. After
operation, a pause must be observed. It is
important that the operator follows the
instructions of the duty cycle; otherwise, a
possible overload may result in reduced
product life/errors
7. W/O #xxxxxxx
The LINAK work order followed by a unique
sequential identification number
* Not a source of ignition in normal operation or when subjected to faults that may be expected, though not on
a regular basis.
CE 0402 II 2D Ex tb IIIC T135°C Db Tamb -25°C to +65°C
*
Combustible dust - conductive
Quality assurance notification body
Equipment for hazardous areas
Non mining
Category 2 equipment for dust
Explosion protection
Protection by Enclosure
Temperature class
Enclosure Zone 21
Ambient temperature
of operation
Page 63
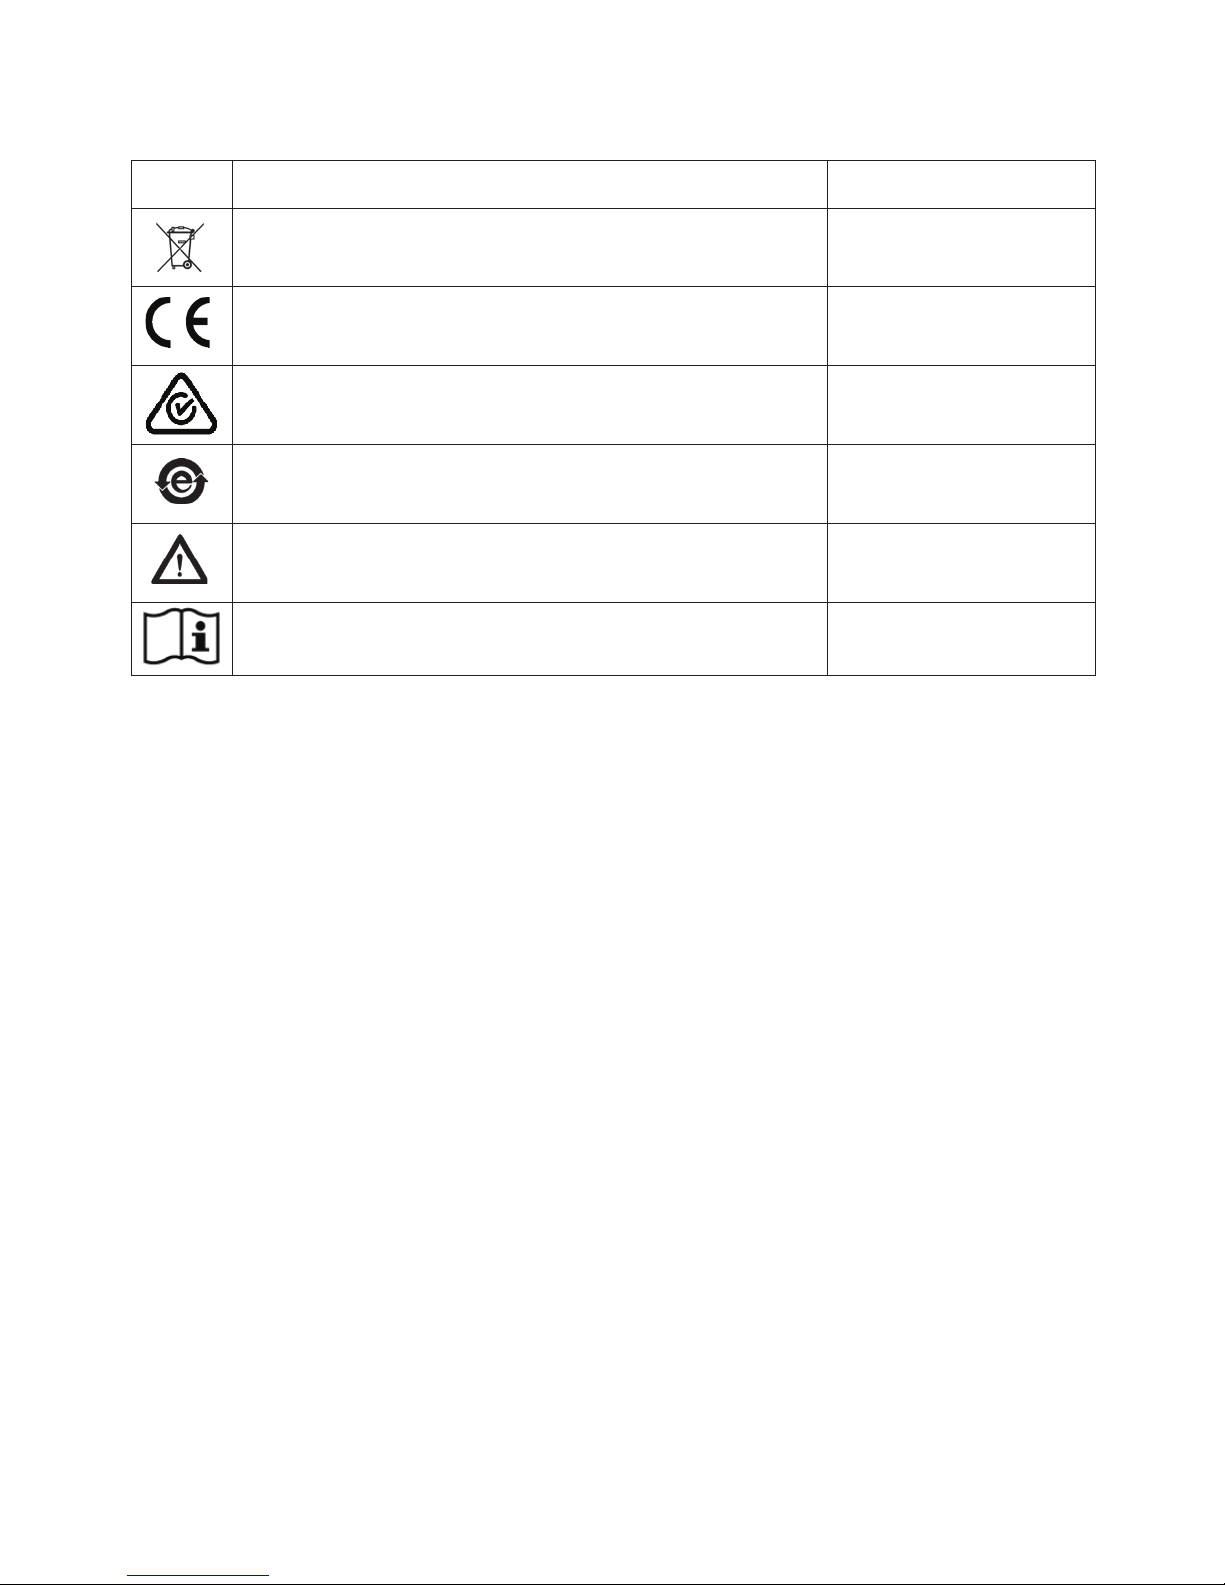
Page 63 of 76
Symbol Norms Approvals
WEEE Directive 2002/96/EC Wheelie bin
Compliance to all relevant EC directives CE
Regulatory Compliance Mark:
The Australian safety/EMC regulations
RCM
China Pollution control mark (also indicates recyclability) China RoHS legislation
ISO 7000- 0434A: Caution
Operating instructions
Key to symbols
The following symbols are used on the LA25 labels:
Page 64
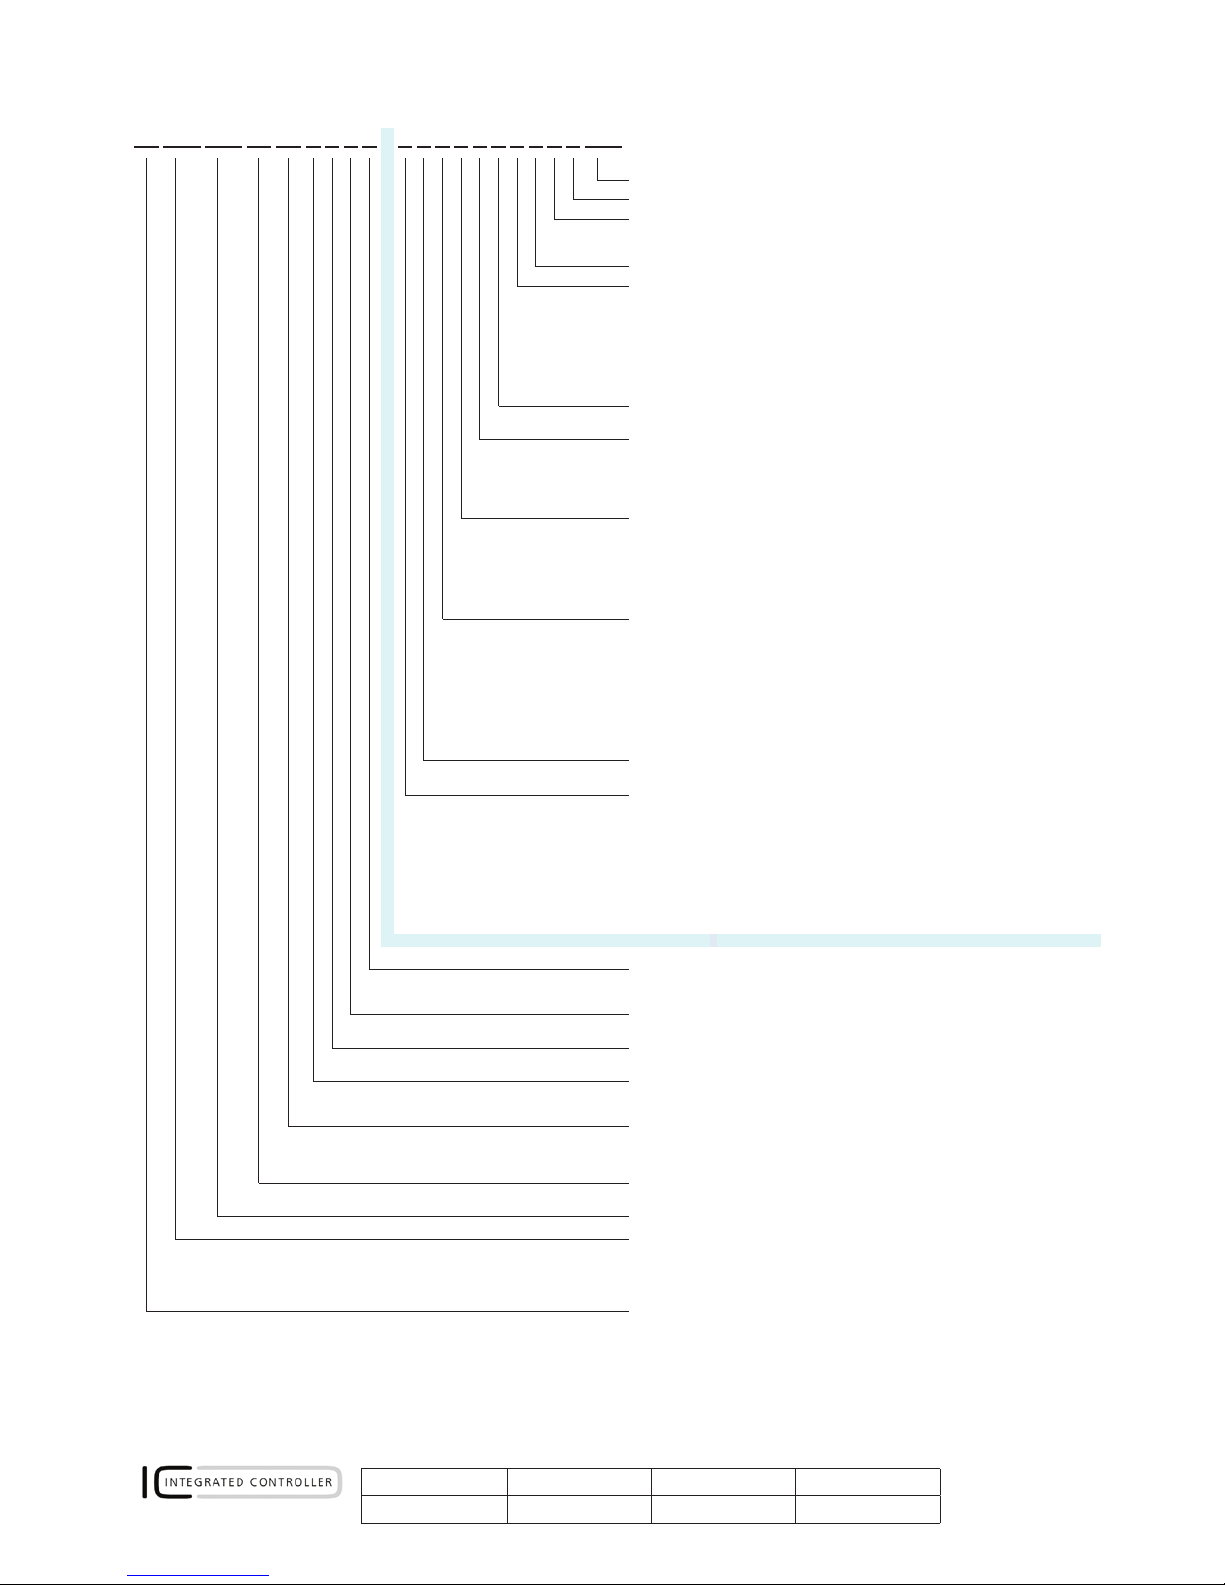
Page 64 of 76
*
IC options: IC LINbus Parallel
LA25 actuator:
� � �
2 5
P P P X X X S S F F = X X X
1 2 3 4 5 6 7 8 9 10 11 12 17 28 29 30
XXX = BID (mm)
0 = Not specified
P Parallelmode 0 = Non critical Parallel
2-8 = critical parallel (count of actuators )
L Loadtype 0 = Push/Pull
1 = Push
2 = Pull
F
Feedback level by platform type
None
IC type Basic
IC type Advanced
IC type Parallel LIN BUS
0 = none 8 = none 0 = none Z = Parallel 0 = LIN adress 0
1 = 0 - 10 V A = 0 - 10 V 1 = LIN adress 1
2 = 0,5 - 4,5 V B = 0,5 - 4,5 V :
3 = 4 - 20 mA C = 4 - 20 mA :
4 = 10 - 90 % D = 10 - 90 % E = LIN adress E
5 = 20 - 80 % E = 20 - 80 % F = LIN adress F
9 = Special feedback X = Special feedback
X = Special LIN software
E EOS output 0 = No (Only IC Basic)
1 = Yes (Only IC Advanced)
C
Cable:
0 = None
S = Straight 0,75m
T = Straight 1,5m (8-core, Note: If AMP is chos en = 6-core)
R = Straight 5,0m (8-core, Note: If AMP is chos en = 6-core)
U = Straight 0,3 m (Only SMPS)
X = Special
P
Plug Type:
0 = None Is to be chosen, if cable and connectors is not wanted
C = Flying leads
Is to be chosen, if connector is not want ed
I = Moulded Deutsch (DT4)
J = Deutsch (DT4)
K= AMP superseal
L= Moulded AMP superseal
S = SMPS (Only cable length 0,3 and 1,5 m)
X = Special
R Piston Rod Eye:
1 = Zink coated steel ø10,2 (0231033) A = Stainless ø10,2 (0231096)
2 = Zink coated steel + bushings ø10,2
B = Stainless + bushings ø10,2
3 = Zink coated steel ø 12,3 (0231016) C = Stainless ø 12,3 (0231095)
4 = Zinc coated steel + bushings ø 8,2
D = Stainless steel + bushings ø 8,2
K = Ball Eye ø10H7 stainless (0351043)
L = Ball Eye ø12H7 stainless (0351035)
F = Female Adapter M8 stainless (0251039)
M = Male Adapter M12 Stainless (231094)
O Backfixture orientation
1 : 0 degrees
2 = 90 degrees
B Back fixture type:
1 = Zink coated steel ø10,2 (0251011) A = Stainless ø10,2 (0251015)
2 = Zink coated steel + bushings ø10,2
B = Stainless + bushings ø10,2
3 = Zink coated steel ø12,3 (0251010) C = Stainless ø 12,3 (0251014)
4 = Zinc coated steel + bushings ø 8,2
D = Stainless steel + bushings ø 8,2
5 = Zink coated steel ø10,2 + Nut (0251032)
F = Stainless steel ø10,2 + Nut (0251034)
6 = Zink coated steel + bushings ø 10,2+Nut G = Stainless steel + bushings ø 10,2+Nut
7 = Zink coated steel ø12,3 + Nut (0251026) H = Stainless steel ø12,3 + Nut (0251033)
8 = Zink coated steel + bushings ø8,2 + Nut
I = Stainless steel + bushings ø8,2 + Nut
M = Male adapter M12 Stainless steel (0251021)
X = special
Colour : = = DarkGrey
I IP: A= IP66
T = ATEX
9 = Harsh environments.
E Endstop : 0 = Power switc h (Platform none)
1 = Signalswitch (Platform IC)
M
Motor Type:
A = 12VDC normal
B = 24VDC. Normal
P Platform 0 = None
3 = IC Integrated Control Not for Openbus
6 = LINBUS
7 = CANBUS
FF
Feedback 00 = none
0K = Single Hall
0A = Hall Potentiometer (Analogue feedback)
0F = PWM
SS Safety :
00 = None
0A = Safety nut
XXX Stroke Length: XXX = mm
PPP
Spindle Pitch:
030 = 3 mm
060 = 6 mm
090 = 9 mm
120 = 12 mm
200 = 20 mm
Actuator Type: 25 = LA25
P M O F L130
18B19
27P21
22C14
15E16I23E20R25P26
24
LA25 ordering example
Page 65
Page 65 of 76
Maintenance
• The actuator must be cleaned at regular intervals to remove dust and dirt and inspected for mechanical
damages or wear.
• Inspect attachment points, wires, piston rod, cabinet, and plug, as well as check that the actuator functions
correctly.
• To ensure that the pregreased inner tube remains lubricated, the actuator
must only be washed down when the
piston rod is fully retracted.
• The actuator is a closed unit and therefore requires no internal maintenance.
• In order to maintain a proper performance of the spherical eyes and to increase the resistance against
environmental wear, we strongly recommend that the spherical eyes (ball bearings) mounted on actuators
from LINAK are greased with anticorrosive grease or similar.
Repair
Only an authorised LINAK® service centre should repair LINAK actuator systems. Systems to be repaired under
warranty must be sent to an authorised LINAK service centre.
In order to avoid the risk of malfunction, all actuator repairs must only be carried out by an authorised LINAK
Service shop or repairer, as special tools and parts must be used.
If a system is opened by unauthorised personel there is a risk that it may malfunction at a later date.
Main groups of disposal
LINAK’s products may be disposed of, possibly by dividing them into different waste groups for recycling or
combustion.
We recommend that our product is disassembled as much as possible at the disposal and that you try to recycle it.
Chapter 5
Product Metal scrap Cable scrap Electronic scrap Plastic recycling or
combustion
LA25 X X X X
Warranty
There is an 18 months’ warranty on TECHLINE products against manufacturing faults calculated from the
production date of the individual products (see label). LINAK’s warranty is only valid in so far as the equipment
has been used and maintained correctly and has not been tampered with. Furthermore, the actuator must not
be exposed to violent treatment. In the event of this, the warranty will be ineffective/invalid. For further details,
please see standard terms of sale and delivery for LINAK A/S.
Note:
Only an authorised LINAK
®
service centre should repair LINAK actuator systems. Systems to be repaired under
warranty must be sent to an authorised LINAK service centre.
In order to avoid the risk of malfunction, all actuator repairs must only be carried out by an authorised LINAK
Service shop or repairer, as special tools and parts must be used.
If a system is opened by unauthorised personel there is a risk that it may malfunction at a later date.
The actuator is
not to be opened by unauthorised personnel. In case the actuator is opened, the warranty will be invalid.
Page 66
Page 66 of 76
DECLARATION OF CONFORMITY
LINAK A/S
Smedevænget 8
DK - 6430 Nordborg
Hereby declares that
Actuator 25XXXXXXXXXXXXXXXXXXXXXXXXXXXX
(The ‘X’ s in the product description can either be a character or a number, thereby defining the variation of the pr oduct)
complies with the EMC Directive: 2014/30/EU according to following harmonized standards:
EN 61000-6-1:2007, EN 61000-6-3:2007, EN 61000-6-2:2005, EN 61000-6-4:2007
complies with the ATEX Directive 2014/34/EU according to following harmonized standards:
EN 60079-0:2012, EN 60079-31:2014
complies with RoHS2 Directive 2011/65/EU according to the harmonized standard:
EN 55581:2012
Additional information:
The device does also comply with the UN ECE Regulation No. 10, Ed. 3, Uniform provisions concerning the approval
of vehicles with regard to electromagnetic compatibility.
Comply with standard:
EN 13309:2010, Construction machinery - Electromagnetic compatibility of machines with internal power supply
EN ISO 14982:2009, Agricultural and forestry machinery - Electromagnetic compatibility - Test methods and
acceptance criteria
ISO 13766:2006, Earth-moving machinery -- Electromagnetic compatibility
ISO 7637-2:2004, Road vehicles -- Electrical disturbances from conduction and coupling -- Part 2: Electrical
transient conduction along supply lines only
Nordborg, 2016-10-12
LINAK A/S
John Kling, B.Sc.E.E.
Certification and Regulatory Affairs
Authorized to compile the relevant technical documentation
Original declaration
Page 67
Page 67 of 76
DECLARATION OF INCORPORATION OF PARTLY COMPLETED MACHINERY
LINAK A/S
Smedevænget 8
DK - 6430 Nordborg
Herewith declares that LINAK TECHLINE ® products
as characterized by the following models and types:
Linear Actuators LA12, LA14, LA22, LA23, LA25, LA30, LA35, LA36, LA37
comply with the following parts of the Machinery Directive 2006/42/EC, ANNEX I, Essential health and
safety requirements relating to the design and construction of machinery:
1.5.1 Electricity supply
The relevant technical documentation is compiled in accordance with part B of Annex VII and that this
documentation or part hereof will be transmitted by post or electronically to a reasoned request by the
national authorities.
This partly completed machinery must not be put into service until the final machinery into
which it is to be incorporated has been declared in conformity with the provisions of the
Machinery Directive 2006/42/EC where appropriate.
Nordborg, 2014-10-20
LINAK A/S
John Kling, B.Sc.E.E.
Certification and Regulatory Affairs
Authorized to compile the relevant technical documentation
Original Declaration
Page 68
Page 68 of 76
Page 69
Page 69 of 76
Page 70
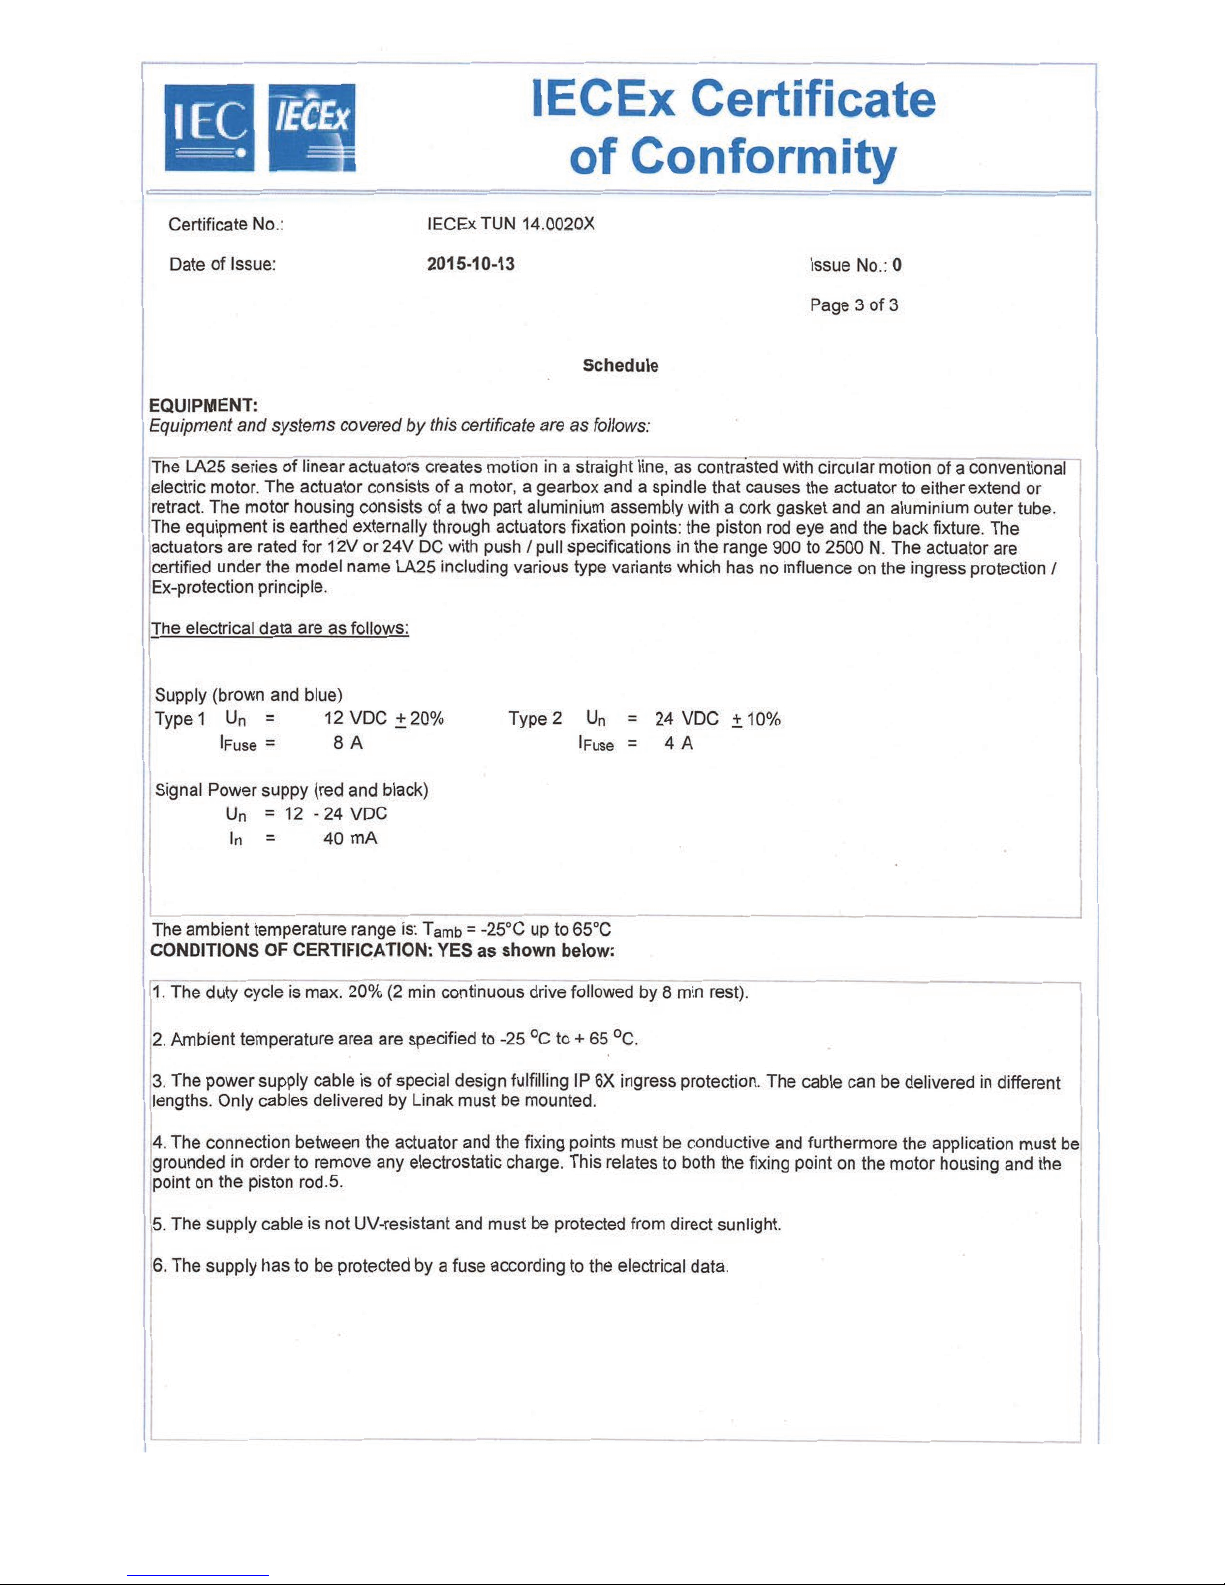
Page 70 of 76
Page 71
Page 71 of 76
Page 72
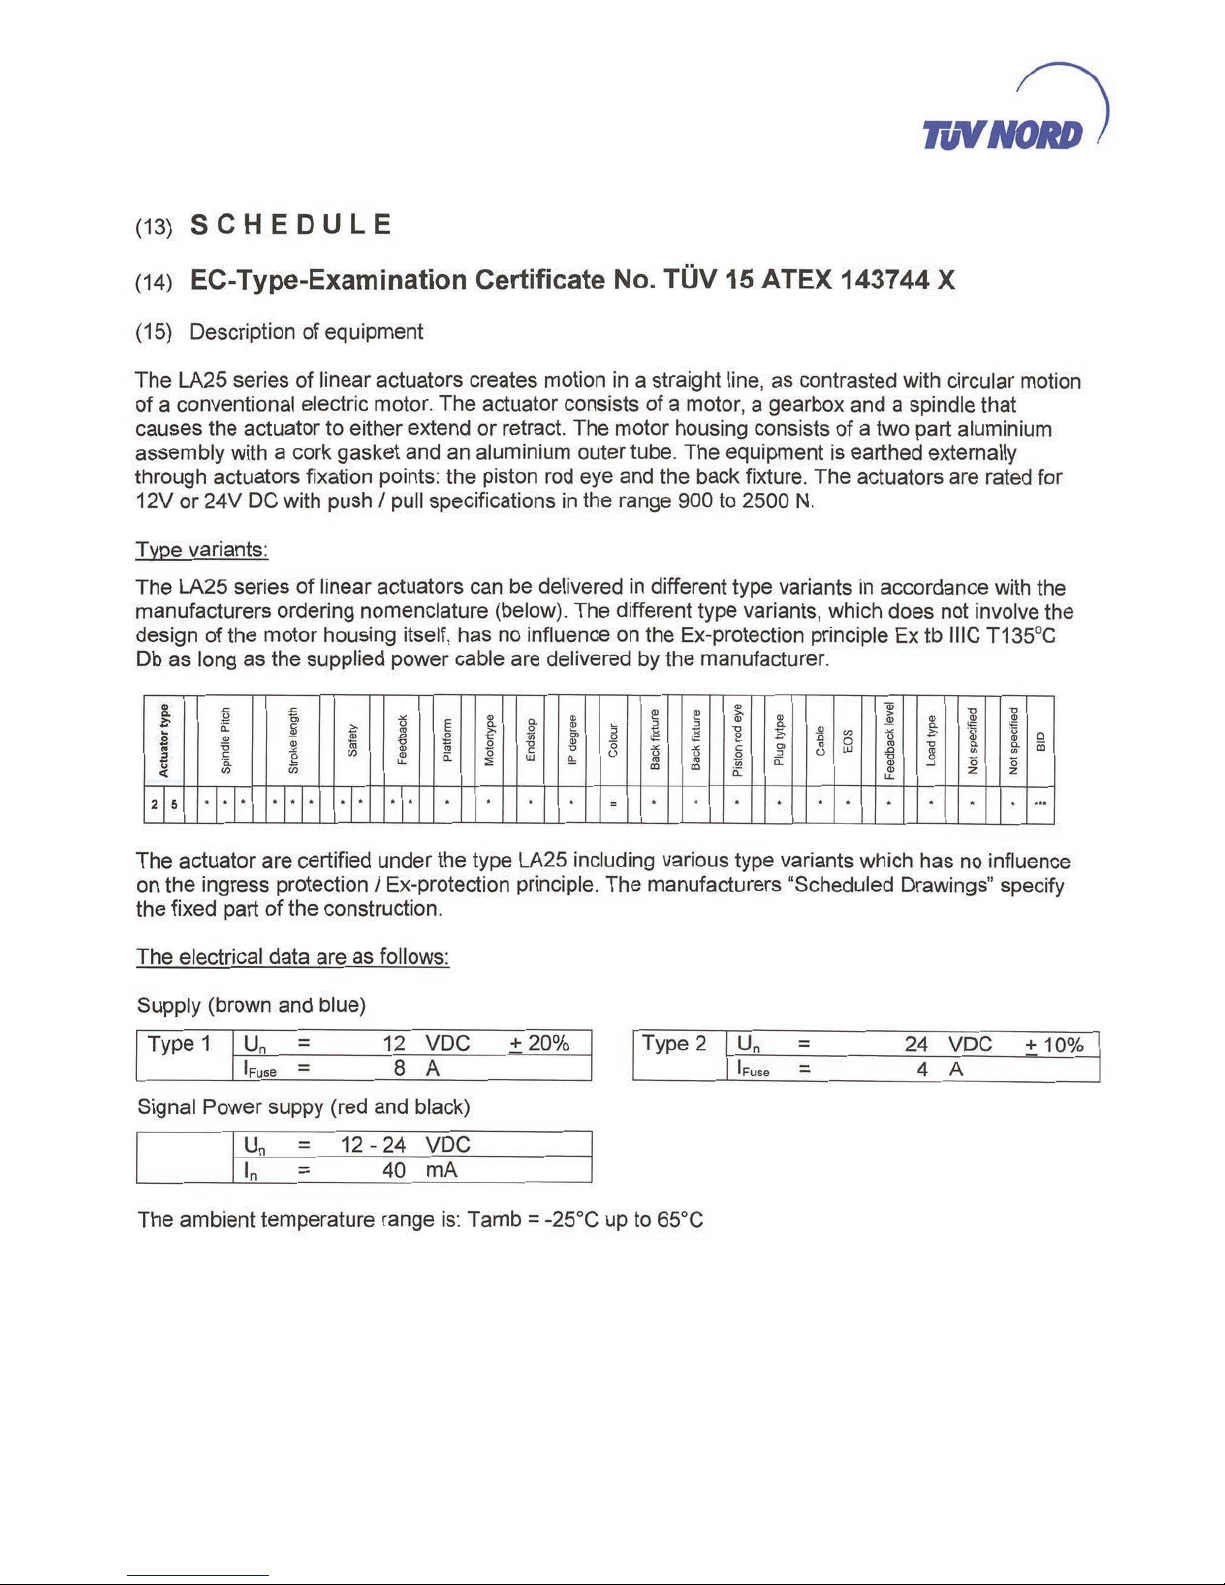
Page 72 of 76
Page 73
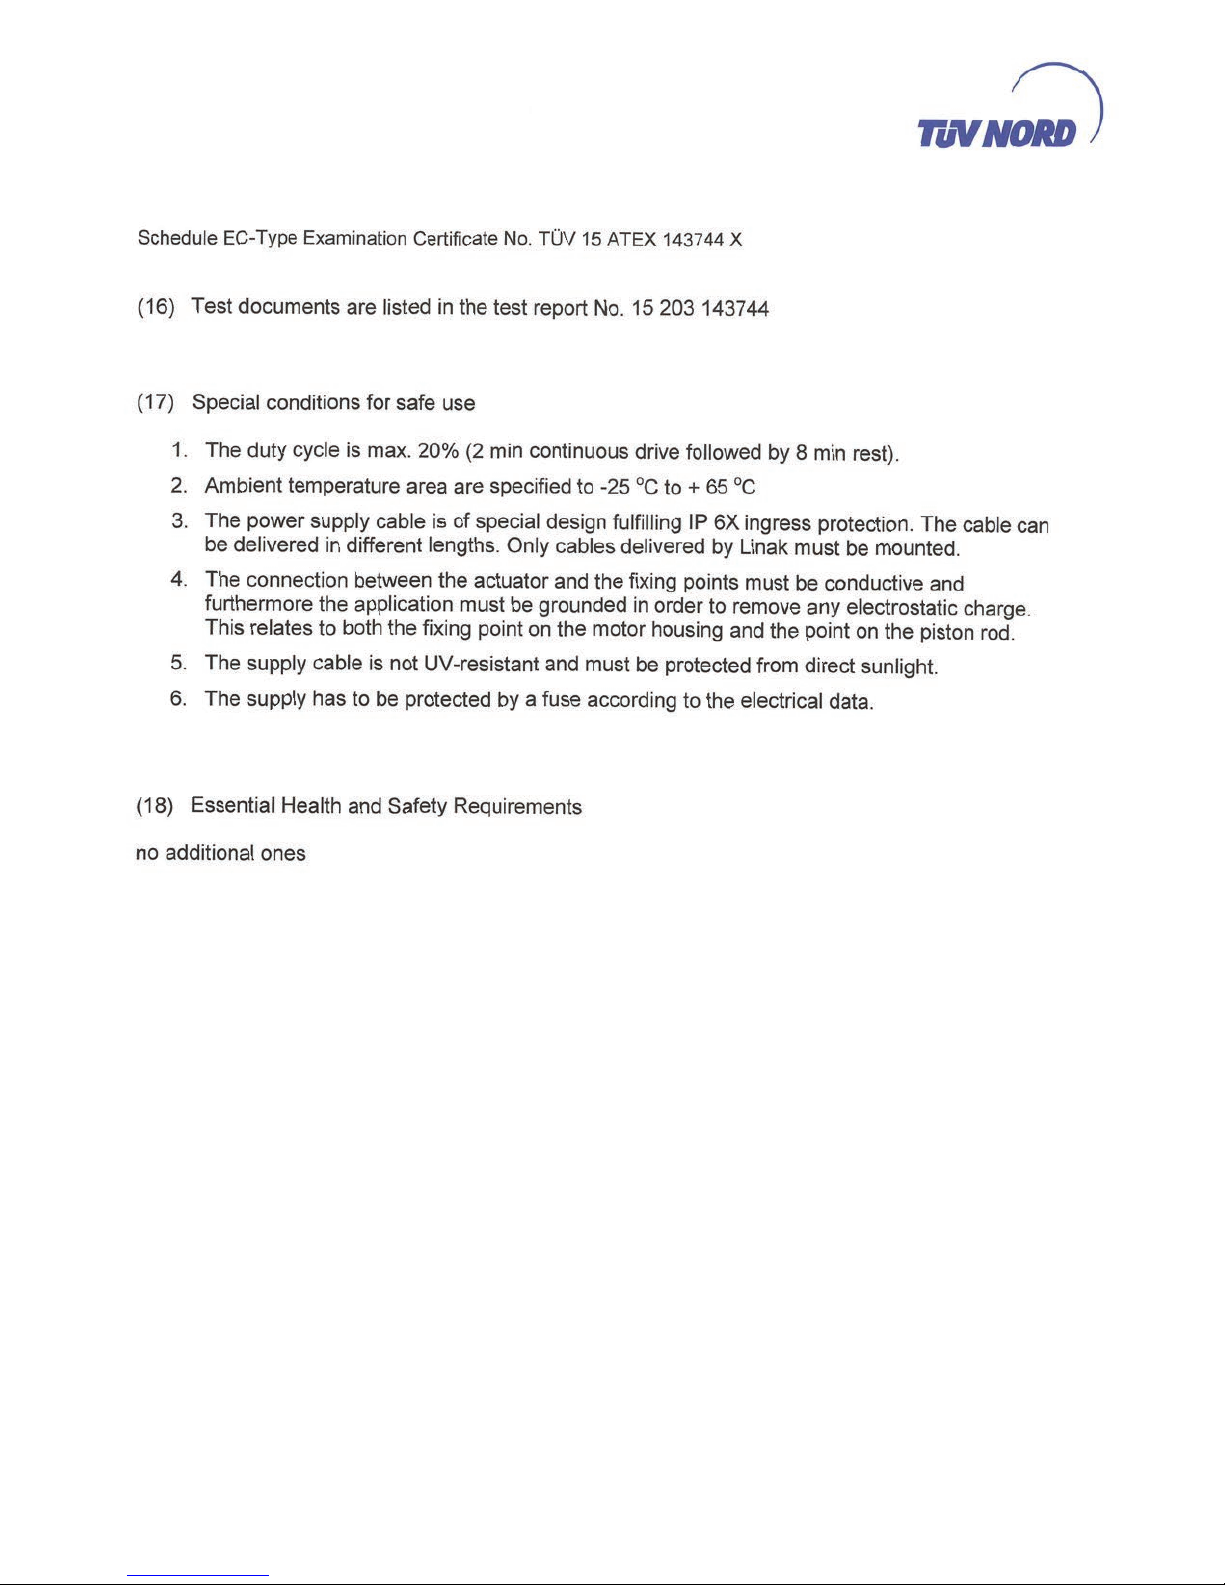
Page 73 of 76
Page 74
Page 74 of 76
Page 75
Page 75 of 76
Page 76
Copyright
©
LINAK 2018.10 MA-M9-02-523-K LINAK A/S reserve the right to make technical alterations
Terms of use
The user is responsible for determining the suitability of LINAK products for specific application. LINAK takes great care in providing accurate and
up-to-date information on its products.
However, due to continuous development in order to improve its products, LINAK products are subject to frequent modifications and changes without
prior notice. Therefore, LINAK cannot guarantee the correct and actual status of said information on its products.
While LINAK uses its best efforts to fulfil orders, LINAK cannot, for the same reasons as mentioned above, guarantee the availability of any particular
product. Therefore, LINAK reserves the right to discontinue the sale of any product displayed on its website or listed in its catalogues or other written
material drawn up by LINAK.
All sales are subject to the Standard Terms of Sale and Delivery for LINAK. For a copy hereof, please contact LINAK.
FACTORIES
China
LINAK (Shenzhen) Actuator Systems, Ltd.
Phone: +86 755 8610 6656
Phone: +86 755 8610 6990
E-mail: [email protected]
www.linak.cn
Denmark - Headquarters
LINAK A/S - Group Headquarters
Phone: +45 73 15 15 15
Fax: +45 74 45 80 48
Fax (Sales): +45 73 15 16 13
E-mail: [email protected]
www.linak.com
USA
LINAK U.S. Inc.
North and South American Headquarters
User support: +1 800 392 7638
Phone: +1 502 253 5595
Fax: +1 502 253 5596
E-mail: [email protected]
www.linak-us.com
SUBSIDIARIES
Australia
LINAK Australia Pty. Ltd
Phone: +61 3 8796 9777
Fax: +61 3 8796 9778
E-mail: [email protected]
www.linak.com.au
Austria
LINAK Repräsentanz - Österreich (Wien)
Phone: +43 (1) 890 7446
Fax: +43 (1) 890 744615
E-mail: [email protected]
www.linak.at
Belgium
LINAK Actuator-Systems NV/SA
(Belgium & Luxembourg)
Phone: +32 (0)9 230 01 09
Fax: +32 (0)9 230 88 80
E-mail: [email protected]
www.linak.be
Brazil
LINAK DO BRASIL COMÉRCIO DE
ATUADORES LTDA.
Phone: +55 (11) 2832 – 7070
Fax: +55 (11) 2832 – 7060
E-mail: [email protected]
www.linak.com.br
C
anada
LINAK Canada Inc.
Phone: +1 502 253 5595
Fax: +1 416-255-7720
E-mail: [email protected]
www.linak-us.com
Czech Republic
LINAK C&S S.R.O.
Phone: +420581741814
Fax: +420581702452
E-mail: [email protected]
www.linak.cz
Denmark - International
LINAK International
Phone: +45 73 15 15 15
E-mail: [email protected]
www.linak.com
Denmark - Sales
LINAK DANMARK A/S
Phone: +45 86 80 36 11
Fax: +45 86 82 90 51
E-mail: [email protected]
www.linak.dk
Finland
LINAK OY
Phone: +358 10 841 8700
E-mail: linak@linak.fi
www.linak.fi
France
LINAK FRANCE E.U.R.L
Phone: +33 (0) 2 41 36 34 34
Fax: +33 (0) 2 41 36 35 00
E-mail: [email protected]
www.linak.fr
Germany
LINAK GmbH
Phone: +49 6043 9655 0
Fax: +49 6043 9655 60
E-mail: [email protected]
www.linak.de
India
LINAK A/S India Liaison Office
Phone: +91 120 4531797
Fax: +91 120 4786428
E-mail: [email protected]
www.linak.in
Ireland
LINAK UK Limited (Ireland)
Phone: +44 (0)121 544 2211
Fax: +44 (0)121 544 2552
+44 (0)796 855 1606 (UK Mobile)
+35 387 634 6554
(Republic Of Ireland Mobile)
E-mail: [email protected]
www.linak.co.uk
Italy
LINAK ITALIA S.r.l.
Phone: +39 02 48 46 33 66
Fax: +39 02 48 46 82 52
E-mail: [email protected]
www.linak.it
Japan
LINAK K.K.
Phone: 81-45-533-0802
Fax: 81-45-533-0803
E-mail: [email protected]
www.linak.jp
Malaysia
LINAK Actuators Sdn. Bhd.
Phone: +60 4 210 6500
Fax: +60 4 226 8901
E-mail: [email protected]
www.linak.my
Netherlands
LINAK Actuator-Systems B.V.
Phone: +31 76 5 42 44 40
Fax: +31 76 5 42 61 10
E-mail: [email protected]
www.linak.nl
New Zealand
LINAK New Zealand Ltd
Phone: +64 9580 2071
Fax: +64 9580 2072
E-mail: [email protected]
www.linak.com.au
DISTRIBUTORS
Argentina
NOVOTEC ARGENTINA SRL
Phone: 011-4303-8989/8900
Fax: 011-4032-0184
E-mail: [email protected]
www.novotecargentina.com
Colombia
MEM Ltda
Phone: +[57] (1) 334-7666
Fax: +[57] (1) 282-1684
E-mail: [email protected]
www.mem.net.co
India
Mechatronics Control Equipments India Pvt Ltd
Phone: +91-44-28558484, 85
E-mail: [email protected]
www.mechatronicscontrol.com
Indonesia
PT. HIMALAYA EVEREST JAYA
Phone: +6 221 544 8956, +6 221 544 8965
Fax: +6 221 619 4658, +6 221 619 1925
E-mail: [email protected]
www.hej.co.id
Israel
NetivTech LTD
Phone: +972 55-2266-535
Fax: +972 2-9900-560
Email: [email protected]
www.netivtech.com
Russian Federation
OOO FAM
Phone: +7 812 3319333
Fax: +7 812 3271454
E-mail: [email protected]
www.fam-drive.ru
Singapore
Servo Dynamics Pte Ltd
Phone: +65 6844 0288
Fax: +65 6844 0070
E-mail: [email protected]
www.servo.com.sg
South Africa
Industrial Specialised Applications CC
Phone: +27 011 466 0346
E-mail: [email protected]
www.isaza.co.za
United Arab Emirates
Mechatronics
Phone: +971 4 267 4311
Fax: +971 4 267 4312
E-mail: [email protected]
Norway
LINAK Norge AS
Phone: +47 32 82 90 90
Fax: +47 32 82 90 98
E-mail: [email protected]
www.linak.no
Poland
LINAK Polska
LINAK Danmark A/S (Spólka Akcyjna)
Phone: +48 22 295 09 70
Phone: +48 22 295 09 71
E-mail: [email protected]
www.linak.pl
Republic of Korea
LINAK Korea Ltd.
Phone: +82-(0)2-6231-1515
Fax: +82-(0)2-6231-1516
E-mail: [email protected]
www.linak.kr
Russian Federation
OOO LINAK
Phone: +7 495 280 14 26
Fax: +7 495 687 14 26
E-mail: [email protected]
www.linak.ru
Spain
LINAK Actuadores, S.L.u
Phone: +34 93 588 27 77
Phone: +34 673 84 40 06
Fax: +34 93 588 27 85
E-mail: [email protected]
www.linak.es
Sweden
LINAK Scandinavia AB
Phone: +46 8 732 20 00
Fax: +46 8 732 20 50
E-mail: [email protected]
www.linak.se
Switzerland
LINAK AG
Phone: +41 43 388 31 88
Fax: +41 43 388 31 87
E-mail: [email protected]
www.de.linak.ch
Taiwan
LINAK (Shenzhen) Actuator systems Ltd.
Taiwan Representative office
Phone: +886 2 27290068
Fax: +886 2 27290096
Mobile: +886 989292100
E-mail: [email protected]
www.linak.tw
Turkey
LINAK İth. İhr. San. ve Tic. A.Ş.
Phone: + 90 312 4726338
Fax: + 90 312 4726635
E-mail: [email protected]
www.linak.com.tr
United Kingdom
LINAK UK Limited
Phone: +44 (0)121 544 2211
Fax: +44 (0)121 544 2552
E-mail: [email protected]
www.linak.co.uk
 Loading...