

Page 1
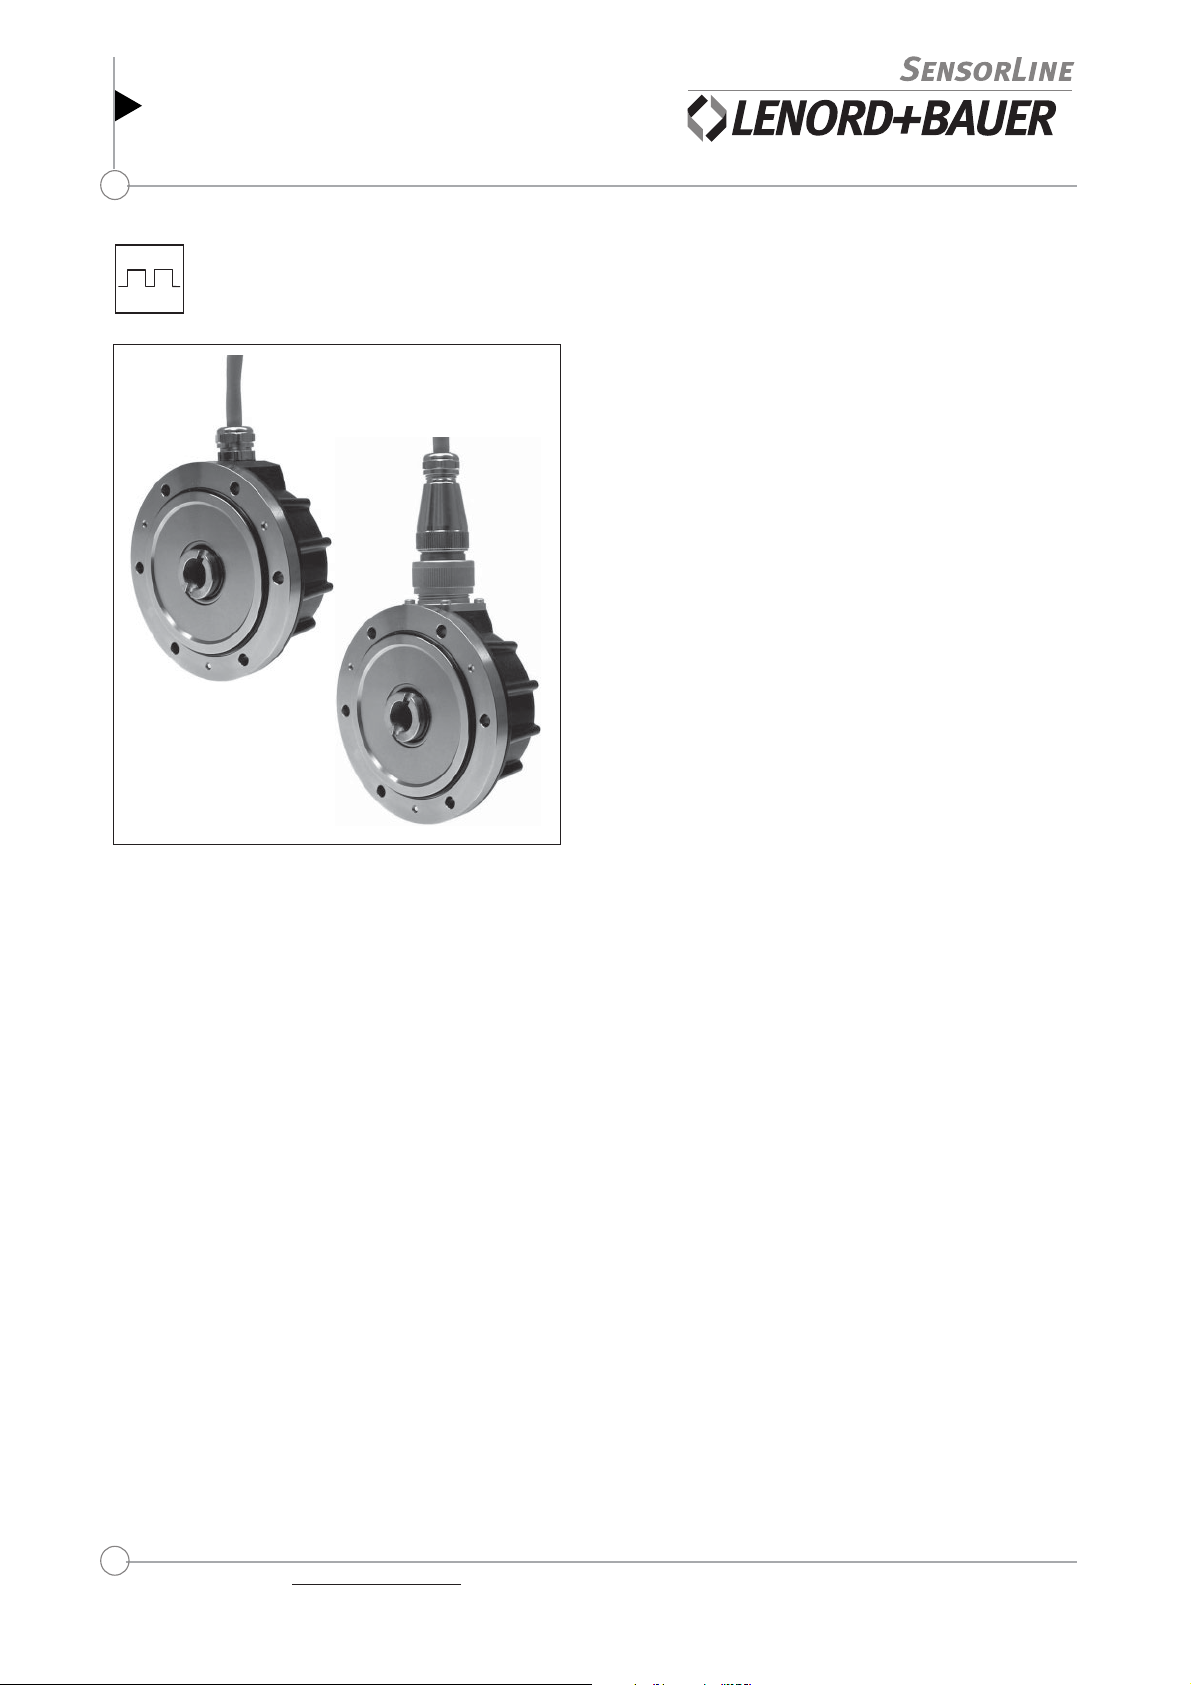
Incremental encoder
GEL 293
- with hollow-shaft and integrated coupling
- magnetic measuring system
Technical information
version 01.05
General information
Incremental encoders convert rotations into electric signals.
The Lenord + Bauer encoders combine the advantages of a
magnetic measuring system and a robust mechanic design.
They have proven successful all over the world in many
different applications and even under roughest industrial
conditions. Their high reliability and a long service life go
without saying.
Fields of application
• Up to 10,000 pulses per revolution (40,000 with
external four-edge evaluation)
• Additionally current output
0 ... 20 mA, 4 ... 20 mA, -20 ... + 20 mA (option)
• Reference signal
• High electromagnetic compatibility (EMC)
Further outstanding features of the GEL 293 are
• A hollow shaft for 16-mm shafts
• A coupling is integrated which is highly elastic and
offers torsional rigidity
• Extremely high angular acceleration
• IP 66
Measuring principle
The encoders work with differential sensors depending on
magnetic fields and a precision toothed wheel as measure.
The sensors scan the tooth structure of the toothed wheel
and emit a sine or cosine voltage. The integrated evaluation
electronics in ASIC and SMD technology converts the
analogue sensor signals into incremental output signals.
Advantages of the magnetic system
• No adverse effect due to condensed water
• Absolute operational reliability even in case of
high humidity (dewing) and frequent change of
ambient temperature
• Extremely insensitive to dirt, oil and water
• Extremely shock- and vibration-resistant
because the measure is not made of glass nor
plastic
• Outstanding operational safety over a
very long period of time as it does not suffer
from ageing effects as optical systems do
Internet: http://www.lenord.de Tel.: +49 (0)208 9963-0 Lenord, Bauer & Co. GmbH
E-Mail: info@lenord.de Fax: +49 (0)208 676292 Dohlenstrasse 32
46145 Oberhausen, Germany
Page 2
Output signals
V
V
X
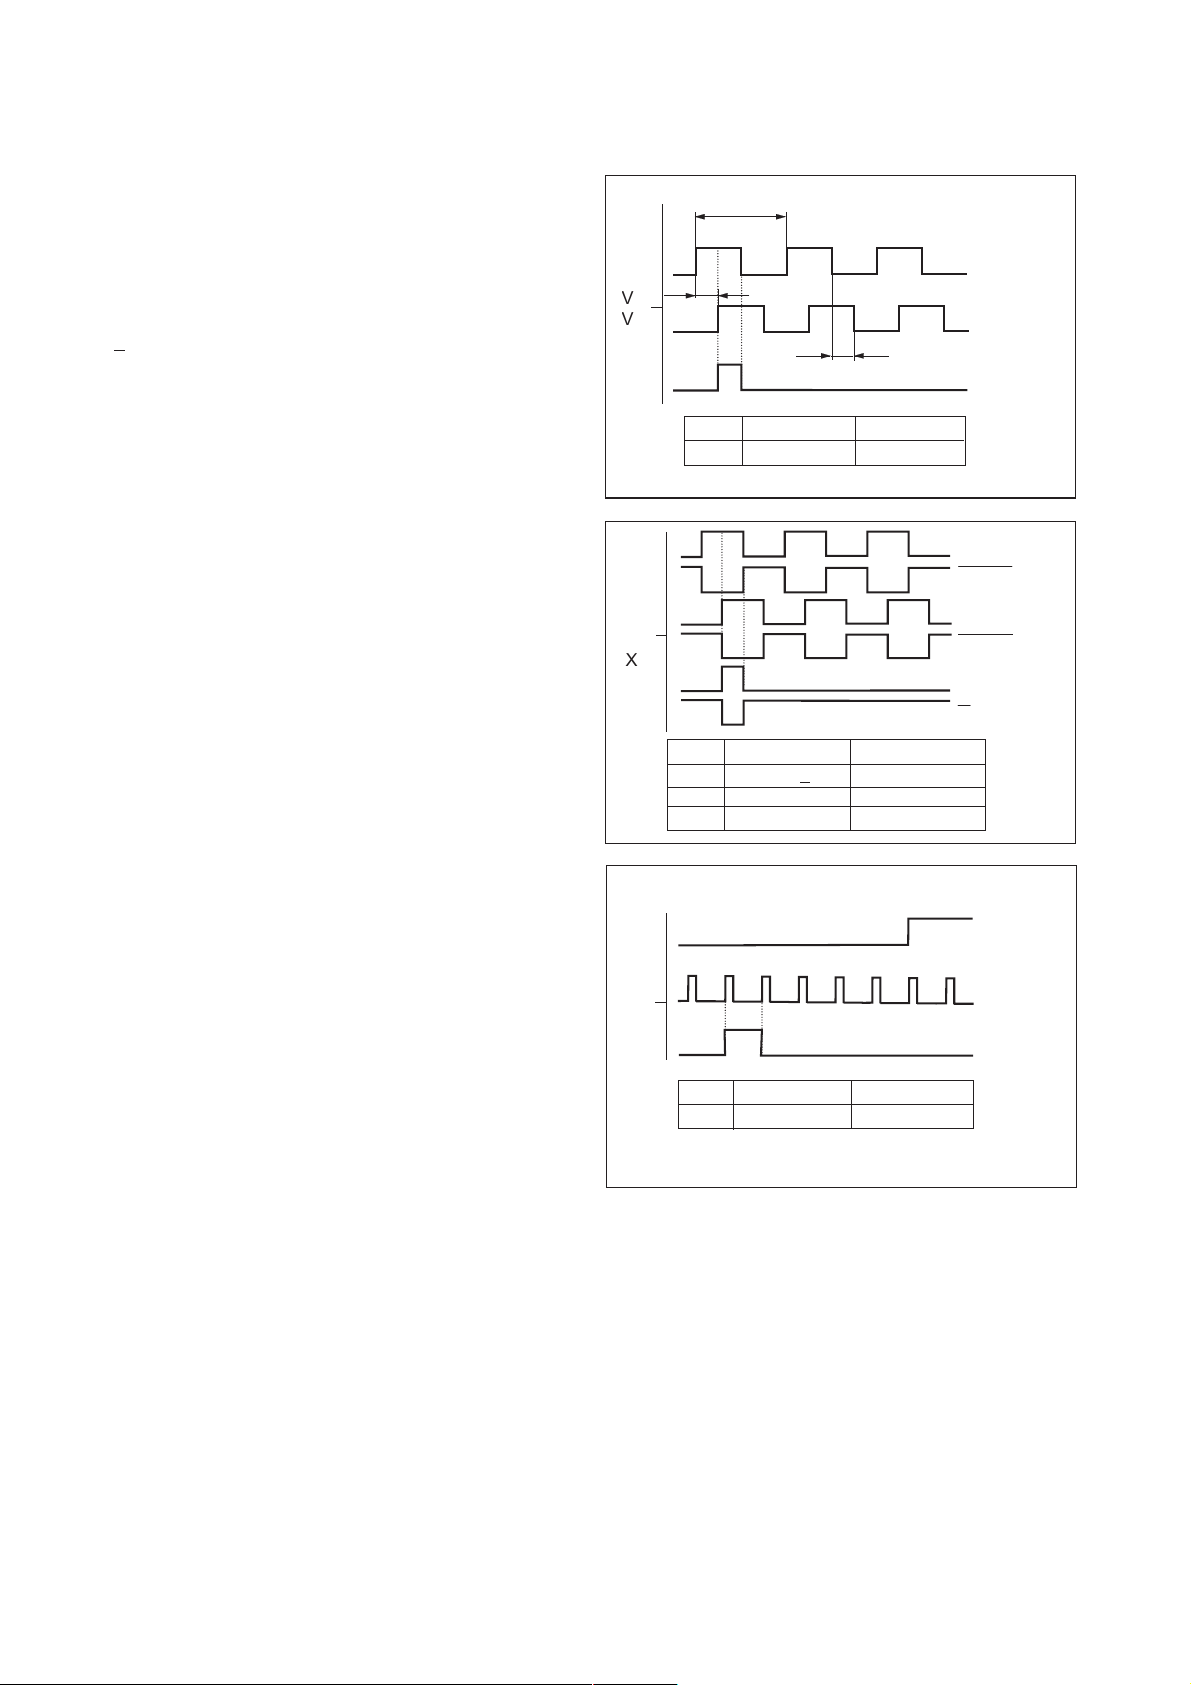
Signal pattern V, VN
Signal pattern "V" stands for two tracks with square-wave
signals, offset by 90° (push-pull output). With each revolution,
a reference signal with defined length is put out on the third
track N (optionally).
At an output frequency of 200 kHz the edge distance (F) is
> 0.6 µs.
Signal pattern T, TN, U, UN, X, XN
Both tracks and the reference signal (option) are
additionally output as inverse signals.
a
b
N
F
t r a c k 1
t r a c k 2
N ( o p t i o n )
U
B
V , V N 1 0 . . . 3 0 V D C H T L
U
S
t r a c k 1
t r a c k 1
T N
U N
N
t r a c k 2
t r a c k 2
N
( o p t i o n )
N
Signal pattern S, SN
Pulses which are independent of the rotational direction and
the duration of which is constant are derived from the
square-wave signals as per signal pattern V and put out on
track 2. Furthermore, a signal depending on the rotational
direction is obtained from the signal pattern which is put on
track 1.
Once per each revolution a reference signal is output on the
third track N (optional). The outputs have a final push-pull
power stage. All outputs are sustained short-circuit-proof.
The pulses follow a possible change of rotation with a slight
delay, in order that a subsequent counter setting can be
adjusted to the counting direction prior to the pulse. The
sense-dependent signal may be reversed via a which is
accessible from outside (switch 1).
Key
UB= operating voltage
US= signal voltage
a = 360° electrical
b = 90° phase shift
F = edge distance (for an output frequency of
200 kHz the edge distance is F > 0.6 µ)
Signal pattern = shown for clockwise rotation (view on top
of the encoder shaft)
Reference signals with other lengths upon request.
U
B
T , T N + 5 V D C + 5 % T T L
U , U N 1 0 . . . 3 0 V D C T T L
X , X N 1 0 . . . 3 0 V D C H T L
U
S
t r a c k 1
S
S N
t r a c k 2
N ( o p t i o n )
U
B
S , S N 1 0 . . . 3 0 V D C H T L
U
S
Output level
The signal patterns V, VN, X and XN have HTL level, the
signal patterns T, TN, U and UN have TTL level (for the
output voltage see electrical data).
All outputs have a push-pull power amplifier and are
short-circuit-proof. The peak output current for recharging
the cable capacity is 100 mA.
2 Lenord +Bauer
DS22-293(01.05)
Page 3
Various current outputs
I
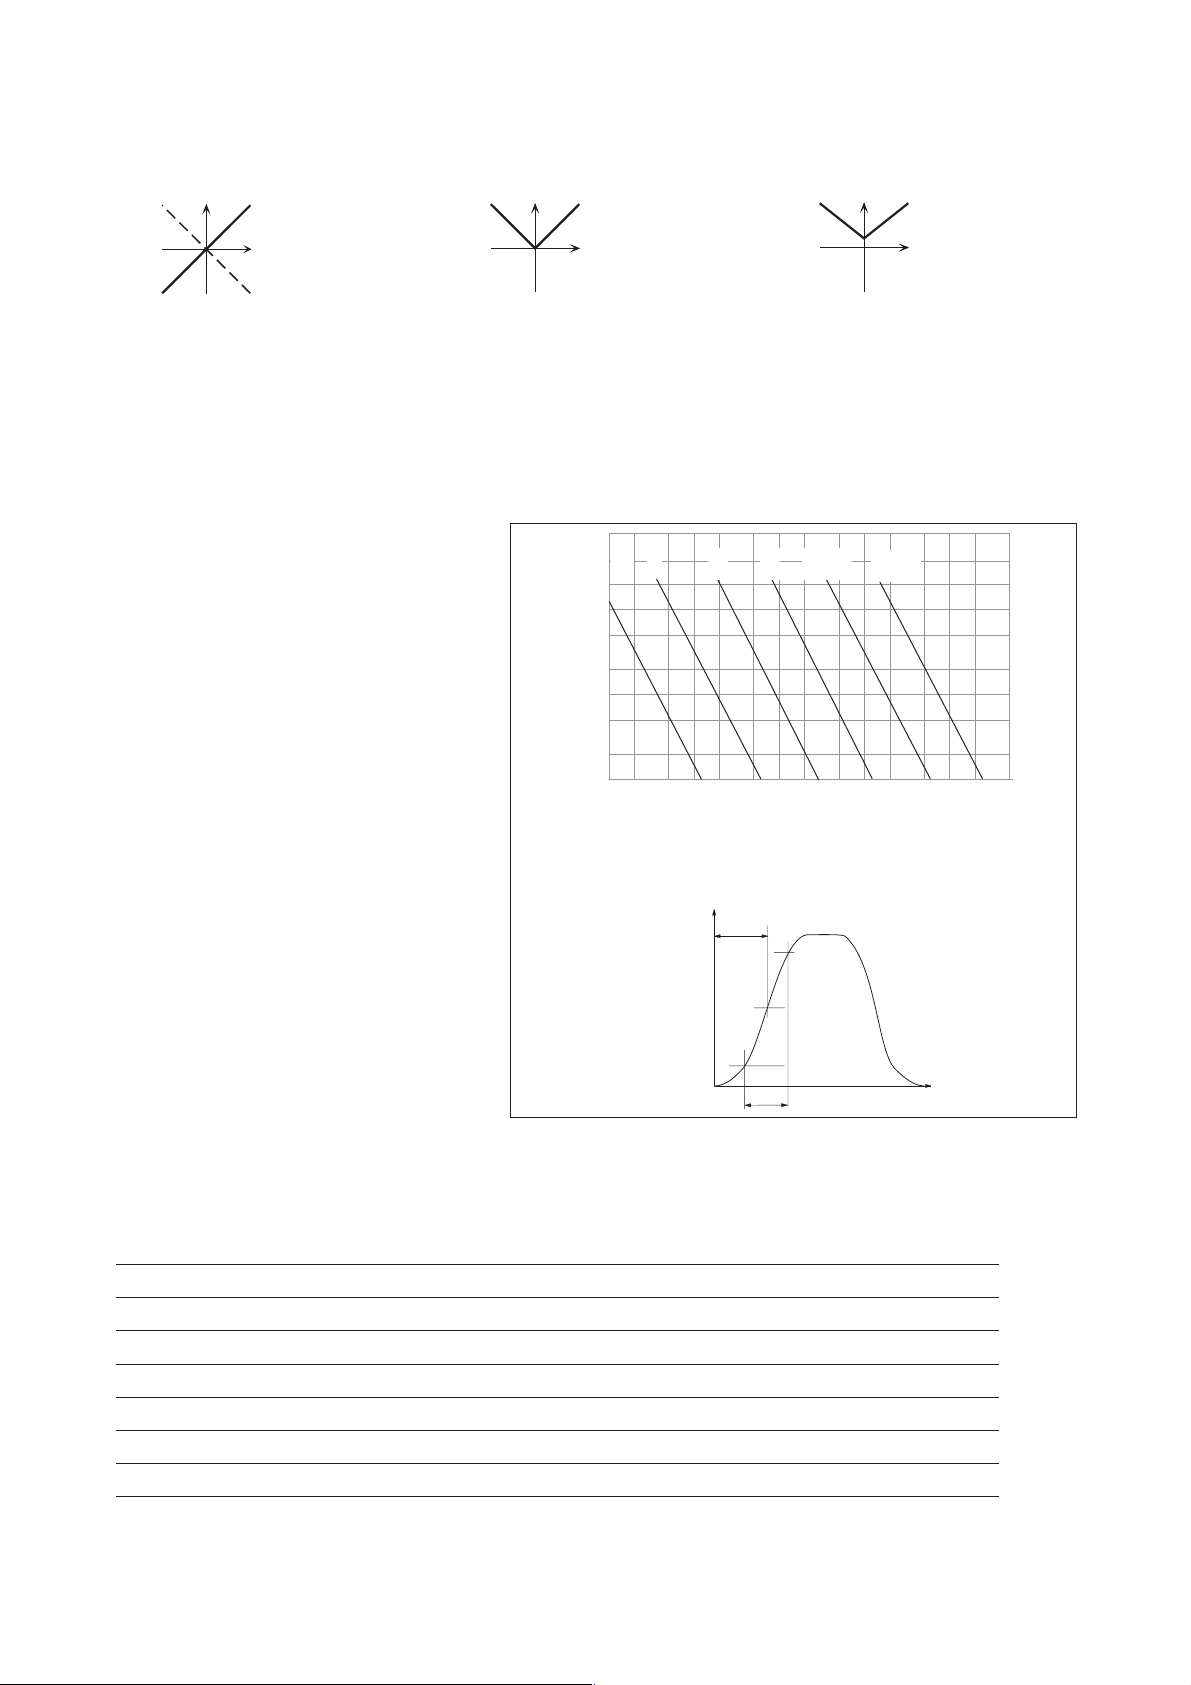
Current outputs
I
I
A :
n
Measuring current which is independent on the sense of rotation and
which has a nominal range of
-20 ... +20 mA.
B :
Measuring current which is
independent of the sense of rotation
and which has a nominal range of
0 ... +20 mA.
Current output
For displaying and controlling a standardized
measuring current of 0 ... 20 mA, 4 ... 20 mA
or -20 ... +20 mA which depends on the
speed and sometimes on the sense of
rotation can be obtained from the pulse
frequency. For this purpose the pulse
frequency is integrated and converted into
an applied current. This results in a strictly
linear interrelation between the measuring
current and the pulse frequency. Because of
the high resolution (up to 40,000 pulses per
revolution, each pulse being dependent on
the sense of rotation) a standard measuring
current with a low harmonic content is
obtained at a very low speed range (e.g.
0 ... 0.5 min
The harmonic content of the output DC
depends on the pulse frequency as well as
on the chosen attenuation, latter influencing
the rise, fall and delay time in case of the
speed changing erratically. Attenuation may
be specified when odering corresponding to
the above diagram, d
-1
) already.
is the default setting.
3
n
%
2 0
1 0
5
2
1
0 . 5
h a r m o n i c c o n t e n t p
0 . 2
0 . 1
1 0 2 0
2 2
1 0 0
1 7
8 0
d
d
5
4
1 0 0 2 0 0 5 0 0
5 0
t
= f ( d )
a , tv
1
p =
f = n x i [ H z ]
1
/
e f f
a
C :
Measuring current which is
independent of the sense of rotation
and which has a nominal range of
+4 ... +20 mA.
4 . 7
1 . 0
3 . 7
d
3
e f f e c t i v e p u l s e f r e q u e n c y f
t
v
a
output current I
0 . 2 2 m s
0 . 8
0 . 1 7 m s
d
2
1 k 2 k 5 k 1 0 k
= rise time
t
a
= delay time
t
v
90 %
50 %
10 %
t
a
d
1
0 . 1 1 m s
0 . 0 8 m s
d
2 0 k
n
t
a
t
v
2 0 0 k
d
[ H z ]
0
1 0 0 k
5 0 k
t
Data of the current outputs
max. apparent ohmic resistance R
a
measuring device class K 1
rated current tolerance < 1 %
linearity error < 1 %
repeatability r 100 %
temperature drift ⌬I
min. RPM n
max. RPM n
DS22-293(01.05)
aT
electrical (attenuation d5) 1.5 x 10³/i RPM
min
electrical 6 x 10⁶/i RPM
max
550 ⍀
< Ⳳ3 µA/1 °K
i = rated pulse number
Lenord +Bauer 3
Page 4
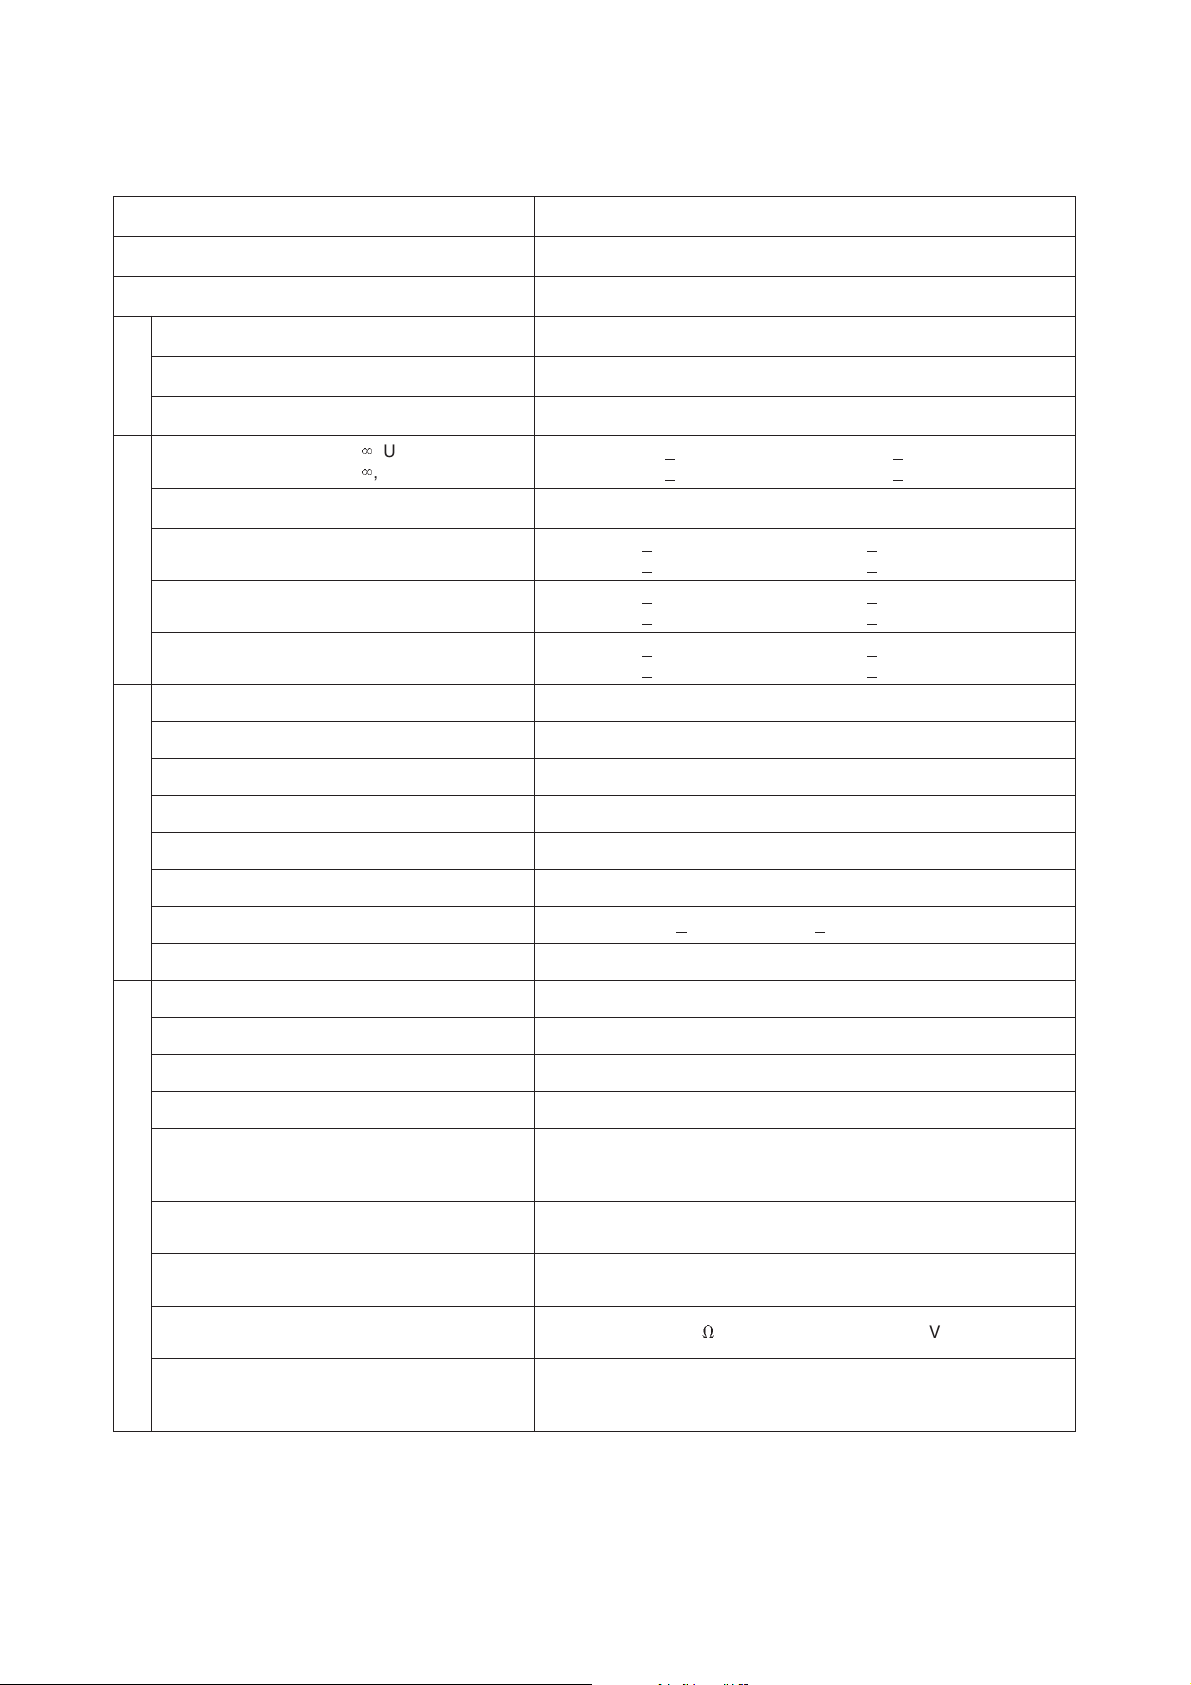
Technical data according to DIN 32878
noitpircseD 392LEG
)1
ot...morfpetsgnirusaem
)1
noituloverreprebmuneslup
)2
timilrorre
)2
noitaivedlatnemercni
accuracymechanical dataenvironmental conditions
)2
ytilibataeper
°780.0...9
seslupforebmun000,04...04
°70.0
°10.0
°500.0
rewop
electrical data
thgiew gk7.0.xorppa
=`U,
R
L
L
=`U,
B
B
noitpmusnoc
R
CDV03…01=
CDV5=
<
<
ycneuqerftuptuo zHk002...0
NT/Tnrettaplangisrofleveltuptuo
)LTTlevelcigol(
NU/Unrettaplangisrofleveltuptuo
)LTTlevelcigol(
,NS/Snrettaplangisrofleveltuptuo
)LTHlevelcigol(NX/XdnaNV/V
U
:langishgih
>
B
<
:langiswol
:langishgih
>
:langiswol
<
:langishgih
>
U
B
:langiswol
<
.m.p.rgnitarepo.xam 000,8
rotorfoaitrenifotnemom 8
noitarelecca.xam 5
euqrotgnitarepo mN10.0
euqrotgnitrats mN510,0
daoltfahselbissimrep+
efilgniraeb 000,51>
erutarepmetgnitarepo )noitpo(C°58+...02-;)dradnats(C°07+...0
.015-
.015-
laixamm1
)3
,+ laidarmm5.0
.016
:tuptuotnerruchtiw(W3.1<)56.1
:tuptuotnerruchtiw(W0.1<)04.1
>
;Am01=ItaV00.1-
U
;Am01=ItaV57.0
;Am01=ItaV00.4
;Am01=ItaV57.0
;Am01=ItaV51.1
B
<
>
<
;Am01=ItaV08.1-
U
>
B
<
Am03=ItaV02.1-
Am03=ItaV00.1
Am03=ItaV58.3
Am03=ItaV00.1
Am03=ItaV02.2-
Am03=ItaV55.1
²mgk
2
s/dar
noitulover
erutarepmettneibma C°58+...02-
erutarepmetegarots C°501+...04-
92506NENIDotgnidroccassalcnoitcetorp 66PI
htiwnoitcetorpyarpsdnatsud
edisegnalfehttagnir-O
66PI.xam,tinugnivirdsassenthgitemas
)tcudtfahsehtroftpecxe(
)noitpo(noitcetorpnoitarbiv
6-2-86006NENIDotgnidrocca
01selcycycneuqerf
)noitpo(noitcetorpkcohs
72-2-86006NENIDotgnidrocca
0660EDVotgnidroccahtgnertsnoitalusni
1-93406NENIDro00/80noisrev005trap
R
M1>
V
i
CAV005foegatlovgnitsetata,
ytilibitapmoccitengamortcele
3-6-00016NEsnoissimmecitengamortcele
2-6-00016NEytinummicitengamortcele
1)
max. value with external evaluation of the signal pattern. See page 7 for possible pulse numbers (resolutions).
2)
value fo highest resolutions. Values for low resolutions on request.
3)
recommended value for minimum pre-tension of the hollow-shaft 1.5 mm
;²s/m001noitareleccakaep;zH000,2...01ycneuqerf
sm11noitarud;²s/m000,1noitareleccakaep
CEE/633/98CMEevitceriDhtiwytimrofnoctcirtsnierasredocneehT
.kramECehtybdeifitreceroferehteradnanoinUnaeporuEehtfo
4 Lenord +Bauer
DS22-293(01.05)
Page 5
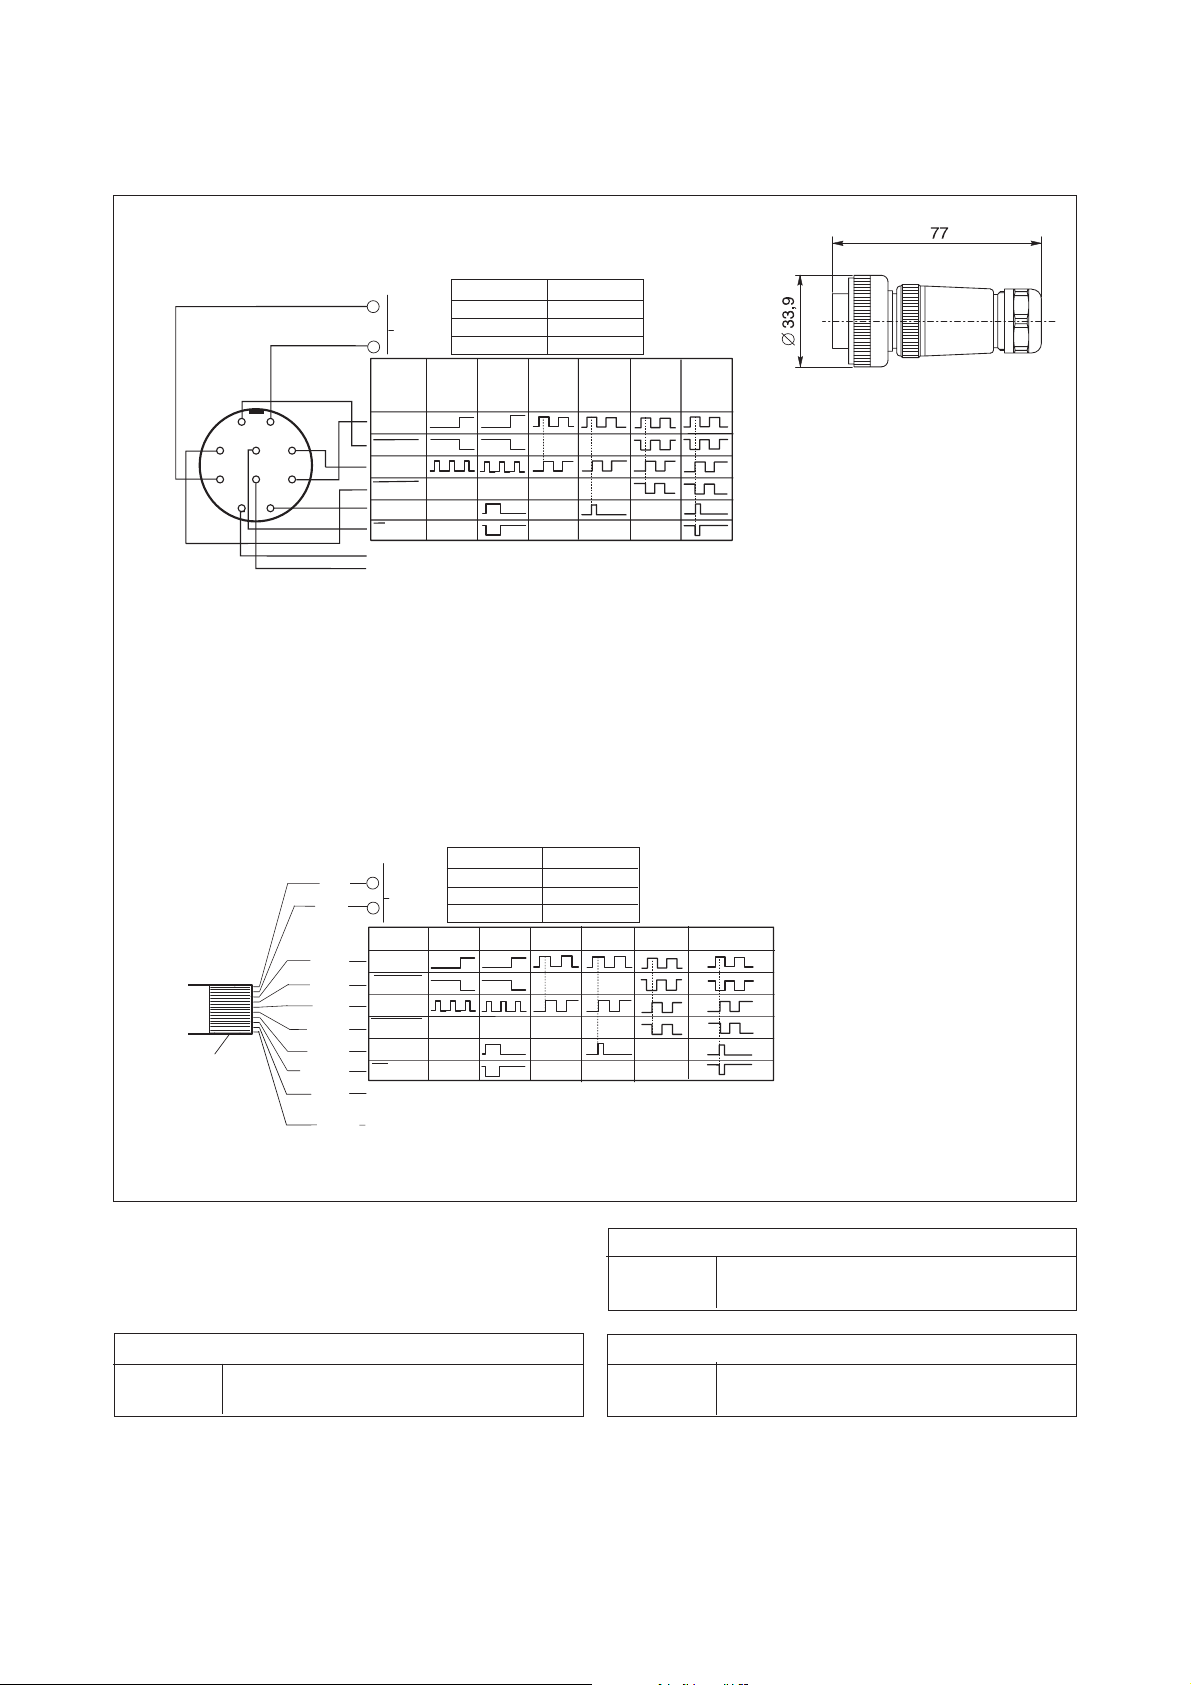
-
Pin layout: connector, cable
-
p
)
Pin layout and dimensioned drawing 10-pole connector GG106
(The counter connector is included in the scope of supply.)
H A
I
G
B
J
C
F
E
D
Pin layout 10-core cable
r e d
b l u e
w h i t e
b r o w n
p i n k
b l a c k
s c r e e n i n g o n
t h e e n c o d e r
s i d e i s n o t
c o n n e c t e d
v i o l e t
y e l l o w
g r e y
g r e e n
U
+
S , X , V 1 0 . . . 3 0 V D C H T L
U 1 0 . . . 3 0 V D C T T L
T + 5 V ± 5 % T T L
t r a c k 1
t r a c k 1
t r a c k 2
t r a c k 2
N .
N .
c u r r e n t o u t p u t A / B /
c h a n g e o f d i r e c t i o n ( s i g n a l p a t t e r n f o r c l o c k w i s e r o t a t i o n
0 V o r o p e n , c h a n g e o f d i r e c t i o n h i g h l e v e l )
S , X , V 1 0 . . . 3 0 V D C H T L
+
U 1 0 . . . 3 0 V D C T T L
T + 5 V ± 5 % T T L
t r a c k 1
t r a c k 1
t r a c k 2
t r a c k 2
N .
N .
c h a n g e o f d i r e c t i o n
c h a n g e o f d i r e c t i o n ( s i g n a l p a t t e r n f o r c l o c k w i s e r o t a t i o n
e n, c h a nge o f d i r e c t i o n h igh l e v e l
0 V o r o
B
S
S N
U
B
S NS
U
S
T
T N
X
X N
U
V N
V
U
S
V NV
T , U , X
U N
T N , U N , X N
UB= operating voltage
US= signal voltage
current output A = -20 mA ... +20 mA
current output B = 0 mA ... +20 mA
current output C = +4 mA ... +20 mA
Signal pattern shown for clockwise
rotation (view on top of the encoder
shaft). Reference signal with other
length upon the request.
Maximum Cable Lengths
between encoder and secondary electronics.
The cable screening is to be earthed one-sided at the
receiver. The stated data are standard values referring to
cable type LiYCY 6 (10) x 0,25 mm
signal pattern TN, UN, level TTL
f [kHz] 5 10 20 50 100 200
L
[m] 200 200 200 200 145 72
max
DS22-293(01.05)
2
.
signal pattern SN, VN, level HTL (UB= 20 V)
f [kHz] 5 10 20 50 100 200
[m] 200 200 200 80 40 20
L
max
signal pattern X, XN, level HTL (U
= 20 V)
B
f [kHz] 5 10 20 50 100 200
L
[m] 200 200 100 40 20 10
max
Lenord +Bauer 5
Page 6
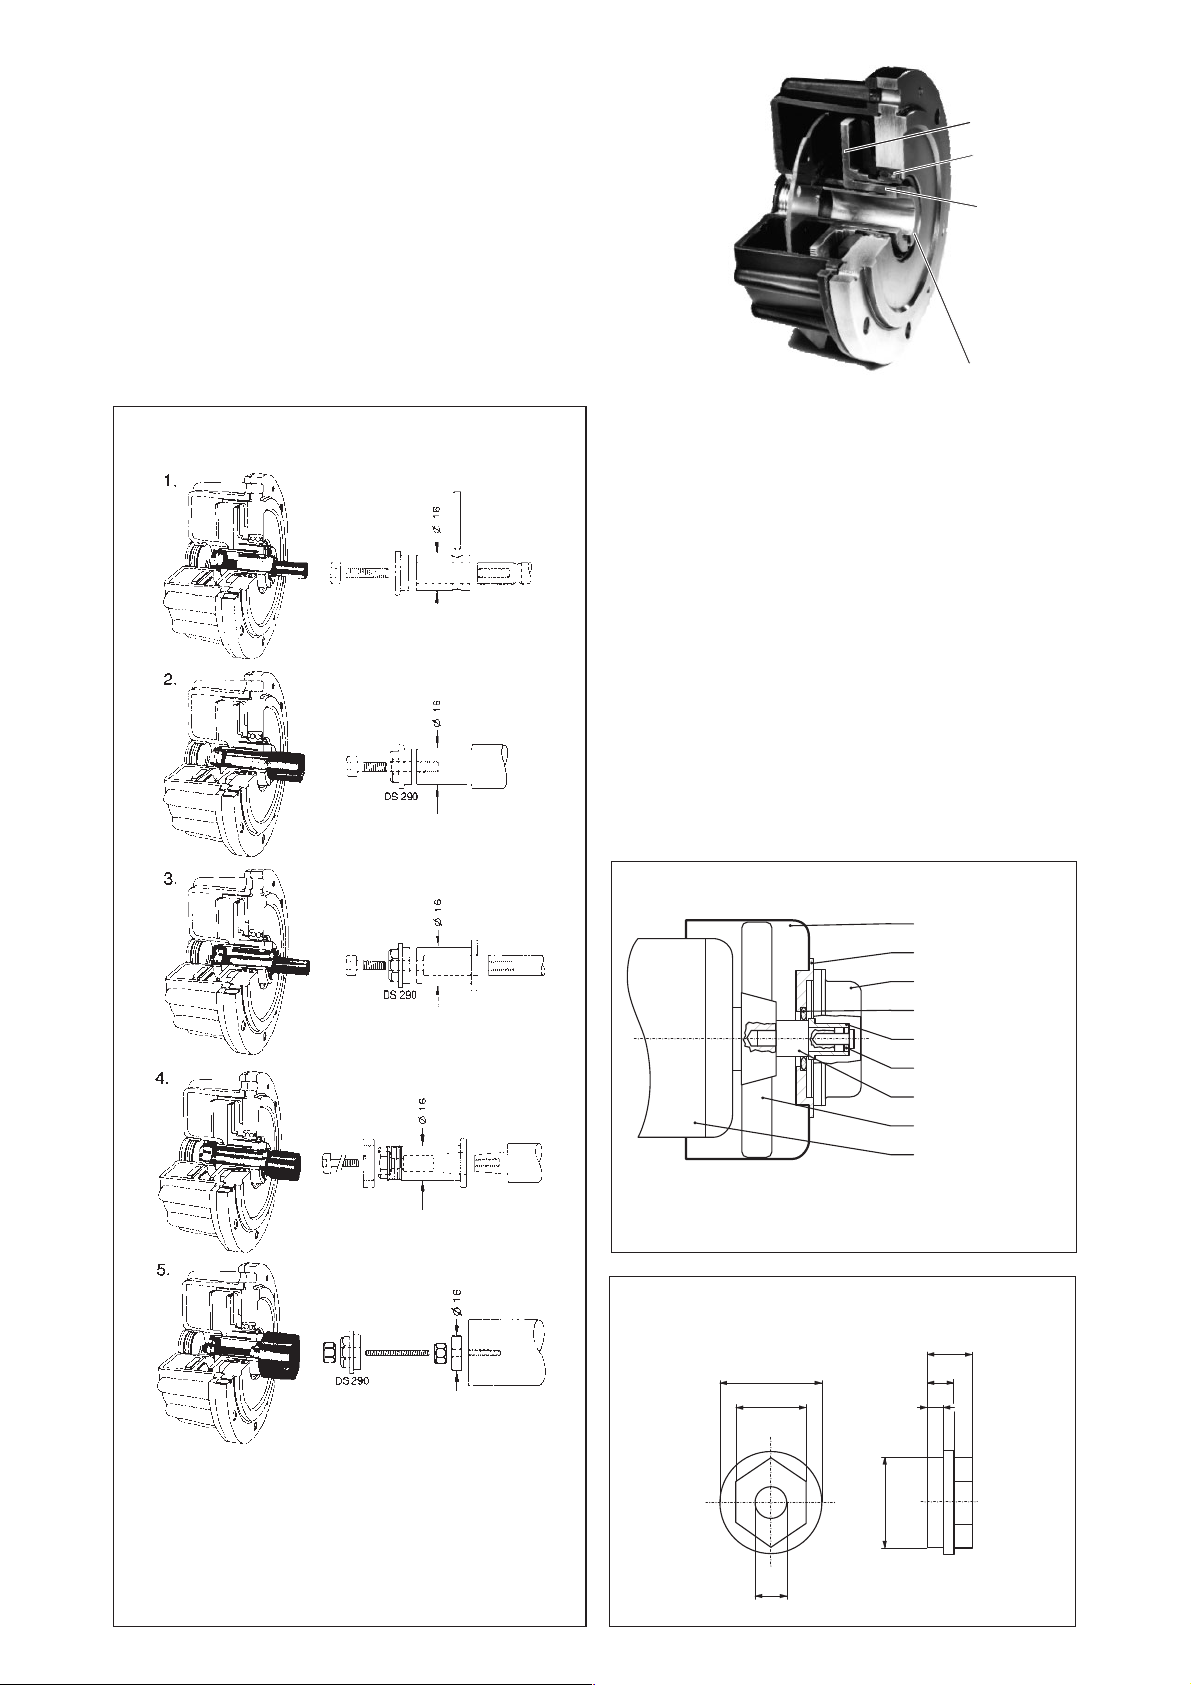
Hollow-Shaft Encoder GEL 293
y
steel pulse
wheel
double-row
angular ball
bearing
coupling,
three
layered
counterwound
spring,
hysteresisfree rotation
angle
hollow shaft
Example for shaft mounting
Protection of the electronics (optional)
Protection against humidity
The encoders’ electronic unit is coated with a highly
effective protection against humidity, salt-water
atmosphere and corrosive vapours to ensure their proper
functioning during years even under roughest conditions.
Condensed-water outlet
Water may accumulate in the encoder if it is exposed to
multiple dewing. The water can drain off through the
condensed-water outlet. When mounting the encoder the
outlet must show downward. The protection class drops
to IP 64.
Protection against vibration
The additional fixing of mechanical parts with special
plastic prevents the electronics and the connections
inside the encoder from vibrating. Thus the proper and
continuous operation of the encoder - even if exposed to
extreme vibration and shock – is guaranteed.
Mounting example incl. counter flange
ventilator cowl
adaptor flange
encoder GEL 293
shaft seal
hollow shaft
clamp disc DS 290
shaft adapter
ventilator
motor
When mounting as shown in examples 2 -5, the
position of the zero signal may be adjusted from
the rear of the mounted encoder.
When attaching the shaft preload coupling
according to dimensioned drawing on page 8.
6 Lenord +Bauer
An adaptor flange is to be used, if the encoder has to
be mounted dust and waterprotected from the flange
side.
Thrust disc DS 290
also see "Examples for shaft mounting"
8.5
18
SW 13
5.5
The clamp disc
DS 290 is part
of deliver
5
3
16
⭋
.
DS22-293(01.05)
Page 7
Possible pulse numbers GEL 293
40 41 42 43 44 45 46 47 48 49 50 51 52 53 54 55 56 57
58 59 60 61 62 63 64 65 66 67 68 69 70 71 72 73 74 75
76 77 78 79 80 81 82 83 84 85 86 87 88 89 90 91 92 93
94 95 96 97 98 99 100 101 102 103 104 105 106 107 108 109 110 111
112 113 114 115 116 117 118 119 120 121 122 123 124 125 126 127 128 129
130 131 132 133 134 135 136 137 138 139 140 141 142 143 144 145 146 147
148 149 150 151 152 153 154 155 156 157 158 159 160 161 162 163 164 165
166 167 168 169 170 171 172 173 174 175 176 177 178 179 180 181 182 183
184 185 186 187 188 189 190 191 192 193 194 195 196 197 198 199 200 201
202 203 204 205 206 207 208 209 210 211 212 213 214 215 216 217 218 219
220 221 222 223 224 225 226 227 228 229 230 231 232 233 234 235 236 237
238 239 240 241 242 243 244 245 246 247 248 249 250 252 254 256 258 260
262 264 266 268 270 272 274 276 278 280 282 284 286 288 290 292 294 296
298 300 302 304 306 308 310 312 314 316 318 320 322 324 326 328 330 332
334 336 338 340 342 344 346 348 350 352 354 356 358 360 362 364 366 368
370 372 374 376 378 380 382 384 386 388 390 392 394 396 398 400 402 404
406 408 410 412 414 416 418 420 422 424 426 428 430 432 434 436 438 440
442 444 446 448 450 452 454 456 458 460 462 464 466 468 470 472 474 476
478 480 482 484 486 488 490 492 494 496 498 500 504 508 510 512 516 520
522 524 528 532 534 536 540 544 546 548 552 556 558 560 564 568 570 572
576 580 582 584 588 592 594 596 600 604 606 608 610 612 616 618 620 624
628 630 632 636 640 642 644 648 650 652 654 656 660 664 666 668 670 672
676 678 680 684 688 690 692 696 700 702 704 708 710 712 714 716 720 724
726 728 730 732 736 738 740 744 748 750 752 756 760 762 764 768 770 772
774 776 780 784 786 788 790 792 796 798 800 804 808 810 812 816 820 822
824 828 830 832 834 836 840 844 846 848 850 852 856 858 860 864 868 870
872 876 880 882 884 888 890 892 894 896 900 904 906 908 910 912 916 918
920 924 928 930 932 936 940 942 944 948 950 952 954 956 960 964 966 968
970 972 976 978 980 984 988 990 992 996 1000 1002 1008 1010 1014 1016 1020 1024
1026 1030 1032 1038 1040 1044 1048 1050 1056 1060 1062 1064 1068 1070 1072 1074 1080 1086
1088 1090 1092 1096 1098 1100 1104 1110 1112 1116 1120 1122 1128 1130 1134 1136 1140 1144
1146 1150 1152 1158 1160 1164 1168 1170 1176 1180 1182 1184 1188 1190 1192 1194 1200 1206
1208 1210 1212 1216 1218 1220 1224 1230 1232 1236 1240 1242 1248 1250 1254 1256 1260 1264
1266 1270 1272 1278 1280 1284 1288 1290 1296 1300 1302 1304 1308 1310 1312 1314 1320 1326
1328 1330 1332 1336 1338 1340 1344 1350 1352 1356 1360 1362 1368 1370 1374 1376 1380 1384
1386 1390 1392 1398 1400 1404 1408 1410 1416 1420 1422 1424 1428 1430 1432 1434 1440 1446
1448 1450 1452 1456 1458 1460 1464 1470 1472 1476 1480 1482 1488 1490 1494 1496 1500 1504
1510 1512 1520 1524 1528 1530 1536 1540 1544 1548 1550 1552 1560 1568 1570 1572 1576 1580
1584 1590 1592 1596 1600 1608 1610 1616 1620 1624 1630 1632 1640 1644 1648 1650 1656 1660
1664 1668 1670 1672 1680 1688 1690 1692 1696 1700 1704 1710 1712 1716 1720 1728 1730 1736
1740 1744 1750 1752 1760 1764 1768 1770 1776 1780 1784 1788 1790 1792 1800 1808 1810 1812
1816 1820 1824 1830 1832 1836 1840 1848 1850 1856 1860 1864 1870 1872 1880 1884 1888 1890
1896 1900 1904 1908 1910 1912 1920 1928 1930 1932 1936 1940 1944 1950 1952 1956 1960 1968
1970 1976 1980 1984 1990 1992 2000 2004 2010 2016 2020 2028 2030 2032 2040 2048 2050 2052
2060 2064 2070 2076 2080 2088 2090 2096 2100 2110 2112 2120 2124 2128 2130 2136 2140 2144
2148 2150 2160 2170 2172 2176 2180 2184 2190 2192 2196 2200 2208 2210 2220 2224 2230 2232
2240 2244 2250 2256 2260 2268 2270 2272 2280 2288 2290 2292 2300 2304 2310 2316 2320 2328
2330 2336 2340 2350 2352 2360 2364 2368 2370 2376 2380 2384 2388 2390 2400 2410 2412 2416
2420 2424 2430 2432 2436 2440 2448 2450 2460 2464 2470 2472 2480 2484 2490 2496 2500 2508
2512 2520 2528 2532 2540 2544 2556 2560 2568 2576 2580 2592 2600 2604 2608 2616 2620 2624
2628 2640 2652 2656 2660 2664 2672 2676 2680 2688 2700 2704 2712 2720 2724 2736 2740 2748
2752 2760 2768 2772 2780 2784 2796 2800 2808 2816 2820 2832 2840 2844 2848 2856 2860 2864
2868 2880 2892 2896 2900 2904 2912 2916 2920 2928 2940 2944 2952 2960 2964 2976 2980 2988
2992 3000 3008 3020 3024 3040 3048 3056 3060 3072 3080 3088 3096 3100 3104 3120 3136 3140
3144 3152 3160 3168 3180 3184 3192 3200 3216 3220 3232 3240 3248 3260 3264 3280 3288 3296
3300 3312 3320 3328 3336 3340 3344 3360 3376 3380 3384 3392 3400 3408 3420 3424 3432 3440
3456 3460 3472 3480 3488 3500 3504 3520 3528 3536 3540 3552 3560 3568 3576 3580 3584 3600
3616 3620 3624 3632 3640 3648 3660 3664 3672 3680 3696 3700 3712 3720 3728 3740 3744 3760
3768 3776 3780 3792 3800 3808 3816 3820 3824 3840 3856 3860 3864 3872 3880 3888 3900 3904
3912 3920 3936 3940 3952 3960 3968 3980 3984 4000 4008 4020 4032 4040 4056 4060 4064 4080
4096 4100 4104 4120 4128 4140 4152 4160 4176 4180 4192 4200 4220 4224 4240 4248 4256 4260
4272 4280 4288 4296 4300 4320 4340 4344 4352 4360 4368 4380 4384 4392 4400 4416 4420 4440
4448 4460 4464 4480 4488 4500 4512 4520 4536 4540 4544 4560 4576 4580 4584 4600 4608 4620
4632 4640 4656 4660 4672 4680 4700 4704 4720 4728 4736 4740 4752 4760 4768 4776 4780 4800
4820 4824 4832 4840 4848 4860 4864 4872 4880 4896 4900 4920 4928 4940 4944 4960 4968 4980
4992 5000 5016 5024 5040 5056 5064 5080 5088 5112 5120 5136 5152 5160 5184 5200 5208 5216
5232 5240 5248 5256 5280 5304 5312 5320 5328 5344 5352 5360 5376 5400 5408 5424 5440 5448
5472 5480 5496 5504 5520 5536 5544 5560 5568 5592 5600 5616 5632 5640 5664 5680 5688 5696
5712 5720 5728 5736 5760 5784 5792 5800 5808 5824 5832 5840 5856 5880 5888 5904 5920 5928
5952 5960 5976 5984 6000 6016 6040 6048 6080 6112 6120 6144 6160 6176 6200 6208 6240 6272
6280 6304 6320 6336 6360 6368 6400 6432 6440 6464 6480 6496 6520 6528 6560 6592 6600 6624
6640 6656 6680 6688 6720 6752 6760 6784 6800 6816 6840 6848 6880 6912 6920 6944 6960 6976
7000 7008 7040 7072 7080 7104 7120 7136 7160 7168 7200 7232 7240 7264 7280 7296 7320 7328
7360 7392 7400 7424 7440 7456 7480 7488 7520 7552 7560 7584 7600 7616 7640 7648 7680 7712
7720 7744 7760 7776 7800 7808 7840 7872 7880 7904 7920 7936 7960 7968 8000 8040 8080 8120
8160 8200 8240 8280 8320 8360 8400 8440 8480 8520 8560 8600 8640 8680 8720 8760 8800 8840
8880 8920 8960 9000 9040 9080 9120 9160 9200 9240 9280 9320 9360 9400 9440 9480 9520 9560
9600 9640 9680 9720 9760 9800 9840 9880 9920 9960 10000
DS22-293(01.05)
The pulse numbers set in bold are standard pulse numbers.
Lenord +Bauer 7
Page 8
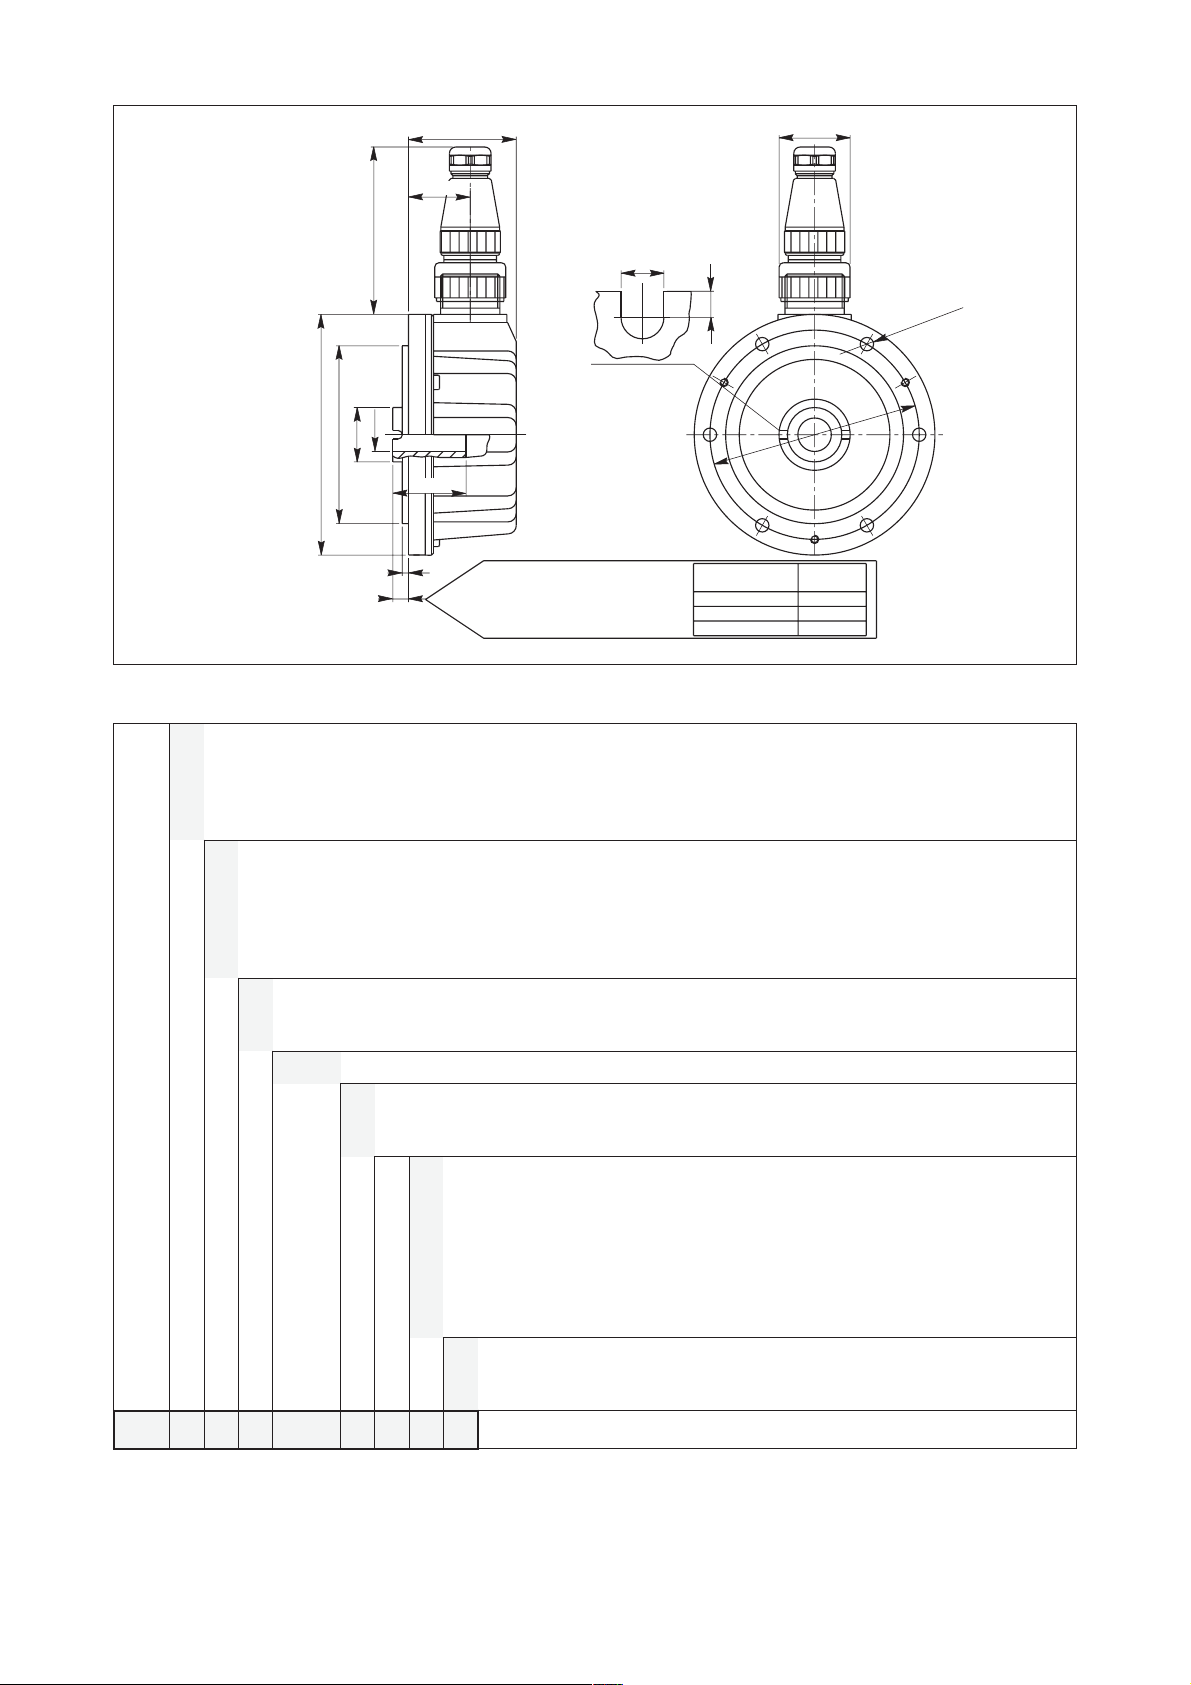
Dimensioned drawing GEL 293 with counter connector GG106
51.5
29.5
Æ
33.9
approx. 80
26
115
16 H7
Æ
85 g7
Æ
Æ
Æ
35
3
A
LEGedocepyT
tuptuotnerruc
A
B
C
392 _ _ _ ____ _ 0 _ _
tuohtiw
Am02+...Am02-
Am02+...Am0
Am02+...Am4+
S
V
X
U
T
Snrettaplangis
Vnrettaplangis
Xnrettaplangis
Unrettaplangis
Tnrettaplangis
langisecnerefer
-
N
tuohtiw
langisecnerefer.lcni
L
I
0
1
2
3
4
5
Please note:
The measure A = 7.5 mm includes
the minimum pre-tension of the
coupling of 1.5 mm at an axial
shaft movement of 1 mm
)2egapees(nrettaplangis
noituloverreprebmuneslup )7egapees(
tuptuoelbac/rotcennoc
rotcennocelop-01
laidar,elbaceroc-01
foorp-erutsiom
foorp-noitarbiv
1
C°07+...C°0
3
4.1
2.5
max. axial
shaft movement
1 mm
2 mm
3 mm
measure A.
min.
7.5 mm
8.5 mm
9.5 mm
100
Æ
6.4 / 6 x 60 °
Æ
scinortceleehtfonoitcetorp
)dradnats(noitcetorplanotiddaynatuohtiw
* When mounting the
encoder the outlet must
foorp-noitarbivdna-erutsiom
show downward.
*teltuoretaw-desnednoc.lcnifofoorp-erutsiom
*teltuoretaw-desnednoc.lcnifofoorp-erutsiom
foorp-noitarbivdna
egnarerutarepmet
)noitpo(C°58+...C°02-
Order details
Standard cable length: 1 metre. Please state in your order, if you wish other cable
length. The counter connector GG 106 is included in the scope of supply, if the
connector option is selected.
Order example
For current outputs please state the nominal speed for I
293 A V N 01000 L001; 3000 U min -1 = 20 mA
8 Lenord +Bauer
max
.
Subject to technical
modifications and
typographical errors.
For the latest version
please visit our web site :
www.lenord.de.
DS22-293(01.05)
 Loading...