

Page 1
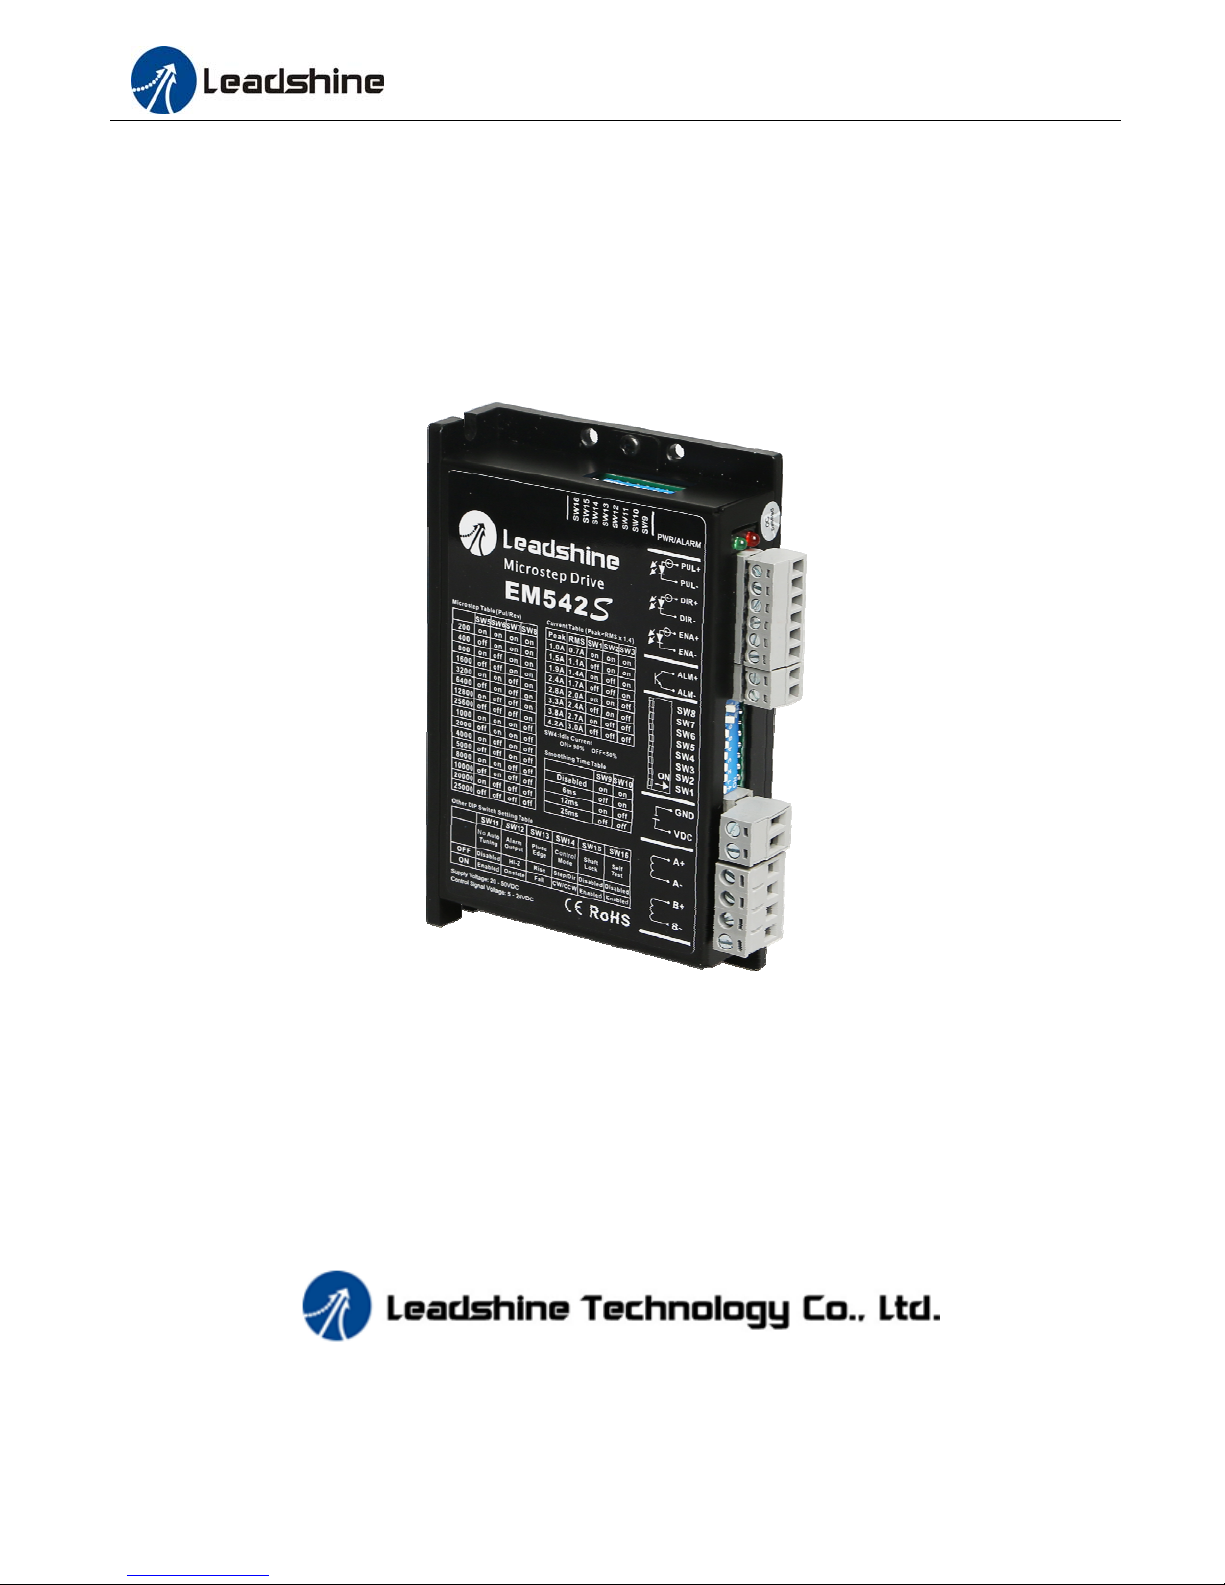
EM542S Digital Stepper Drive User Manual
UserManual
EM542S
DigitalStepperDrive
Revision 1.0
©2017 AllRightsReserved
Page 2
EM542S Digital Stepper Drive User Manual
Important Notice
Read thismanual carefullybeforeanyassemblingandusing. Incorrecthandlingofproducts inthismanual can result
in injury and damage to persons and machinery. Strictly adhere to the technical information regarding installation
requirements.
ThismanualisnotforuseordisclosureoutsideofLeadshineexceptunderpermission.Allrights
arereserved.Nopart
of this manual shall be reproduced, stored in retrieval form, or transmitted by any means, electronic, mechanical,
photocopying, recording, or otherwise without approval from Leadshine. While every precaution has been taken in
the preparation of the book, Leadshine assumes no responsibility for errors or omissions. Neither
is any liability
assumedfordamagesresultingfromtheuseoftheinformationcontainedherein.
This document is proprietaryinformation of Leadshine that is furnishedfor customeruse ONLY. Information in this
document is subject to change without notice and does not represent a commitment on the part of Leadshine.
Therefore,
information contained in thismanual maybe updated from time‐to‐time due to product improvements,
etc.,andmaynotconf ormineveryrespecttoformerissues.
RecordofRevisions
Revision Date DescriptionofRelease
1.0 Oct,2017 InitialRelease
Page 3
EM542S Digital Stepper Drive User Manual
TableofContents
1. Introduction ............................................................................................................................................................. 1
1.1 Features ................................................................................................................................................................ 1
1.2 Applications ......................................................................................................................................................... 1
2.1 Electrical Specifications ...................................................................................................................................... 2
2.2 Environment ........................................................................................................................................................ 2
2.3 Mechanical Specifications ................................................................................................................................... 2
2.4 Elimination of Heat .............................................................................................................................................. 3
3. Connection Pin Assignments and LED Indication .................................................................................................... 3
3.1 P1 - Control Connector Configurations ............................................................................................................... 3
3.2 P2 - Fault Output Connector ................................................................................................................................ 4
3.3 P3 - Power Connector .......................................................................................................................................... 4
3.3 P4 - Motor Connector .......................................................................................................................................... 4
3.5 Status LED Lights ................................................................................................................................................ 4
4. Control Signal and Fault Output ............................................................................................................................... 4
4.1 Control Signal Connection .................................................................................................................................. 4
4.2 Fault output connection ....................................................................................................................................... 5
5. Stepper Motor Connections .................................................................................................................................... 5
5.1 4-lead Motor Connection ..................................................................................................................................... 5
5.2 6-lead Motor Connection ..................................................................................................................................... 6
5.3 8-lead Motor Connection ..................................................................................................................................... 6
5.3.1 Series Connection ..................................................................................................................................... 6
5.3.2 Parallel Connection ................................................................................................................................... 6
6. Power Supply Selection ........................................................................................................................................... 7
6.1 Regulated or Unregulated Power Supply ............................................................................................................. 7
6.2 Power Supply Sharing ......................................................................................................................................... 7
6.3 Selecting Supply Voltage ..................................................................................................................................... 7
7. DIP Switch Configurations ..................................................................................................................................... 7
7.1 Output Current Configuration (SW1-3) ........................................................................................................... 8
7.2 Idle Current Configuration (SW4) ................................................................................................................... 8
7.3 Micro Step Configuration (SW5-8) .................................................................................................................. 9
7.4 Filter Time Configuration (SW9-10) ................................................................................................................... 9
7.5 No Auto Tuning Configuration (SW11) ........................................................................................................... 9
7.6 Alarm Output Configuration (SW12) ............................................................................................................. 10
7.7 Pulse Edge Configuration (SW13) ............................................................................................................... 10
7.8 Control Mode Configuration (SW14) ........................................................................................................... 10
7.9 Shaft Lock Configuration (SW15) ................................................................................................................. 10
7.10 Self-Test Configuration (SW16) ................................................................................................................ 10
8. Wiring Notes ............................................................................................................................................................... 10
9. Typical Connection .................................................................................................................................................... 11
10. Sequence Chart of Control Signals ........................................................................................................................ 11
Page 4
EM542S Digital Stepper Drive User Manual
11. Protection Functions ................................................................................................................................................ 12
12. Troubleshooting ....................................................................................................................................................... 13
13. Warranty .................................................................................................................................................................. 14
14. Contact Us ................................................................................................................................................................ 15
Page 5
EM542S Digital Stepper Drive User Manual
1. Introduction
The EM542S is a new digital stepper drive based on Leadshine’s widely implemented DM stepper drives (10+ millions
of units in field). While retaining features of simple design, easy setup, high precision and reliability, Leadshine has
also upgraded it by adopting the latest stepper control technology and added additional advanced features for better
torque (10-25%), quicker response time, control command smoothing, easy self-test, etc.
The EM542S is able to power 2 phase (1.8°) and 4 phase (0.9°) stepper motors smoothly with very low motor heating
& noise. It can take 20-50VDC supply voltage and output 1.0 to 4.2A current. All the micro step and output current
configurations can be easily done via built in DIP switches. Its control type (step & direction or CW/CCW) and
command smooth filtering can also be configured via DIP switches. Therefore, the EM542S is an ideal choice for
many applications requiring simple step & direction or CW/CCW control of NEMA 17, 23, and 24 stepper motors.
1.1 Features
Step & direction (PUL/DIR) or CW/CCW (double pulse) control
20-50VDC supply voltage
200 KHz max pulse input frequency
16 micro-step resolutions of 200-25,600 via DIP switches
8 output current settings of 1.0 – 4.2A via DIP Switches
Configurable control command smoothing for performance excellence
Automatic idle current reduction to 50% or 90%
Convenient self-test for easy diagnosis
Automatic self-configuration to match wide-range NEMA 17, 23, and 24 stepper motors
Anti-Resonance for optimal torque, extra smooth motion, low motor heating and noise
Soft-start with no “jump” when powered on
Optically isolated inputs
Fault output
Over-voltage and over-current protections
CE certified and RoHS compliant
1.2 Applications
The EM542S stepper drive is designed to power 2 phase (1.8°) or 4-phase (0.9°) NEMA 17, 23, and 24 hybrid stepper
motors. It can be adopted in many industries (CNC machinery, electronics, medical, automation, packaging…) for
applications such as CNC routers, mills, plasma, laser cutters, factory assembly lines, vending machines, etc. Its
excellent performance, simple design, and easy setup features make EM542S ideal for many step & direction control
type applications.
Page | 1
Page 6
EM542S Digital Stepper Drive User Manual
2. Specifications
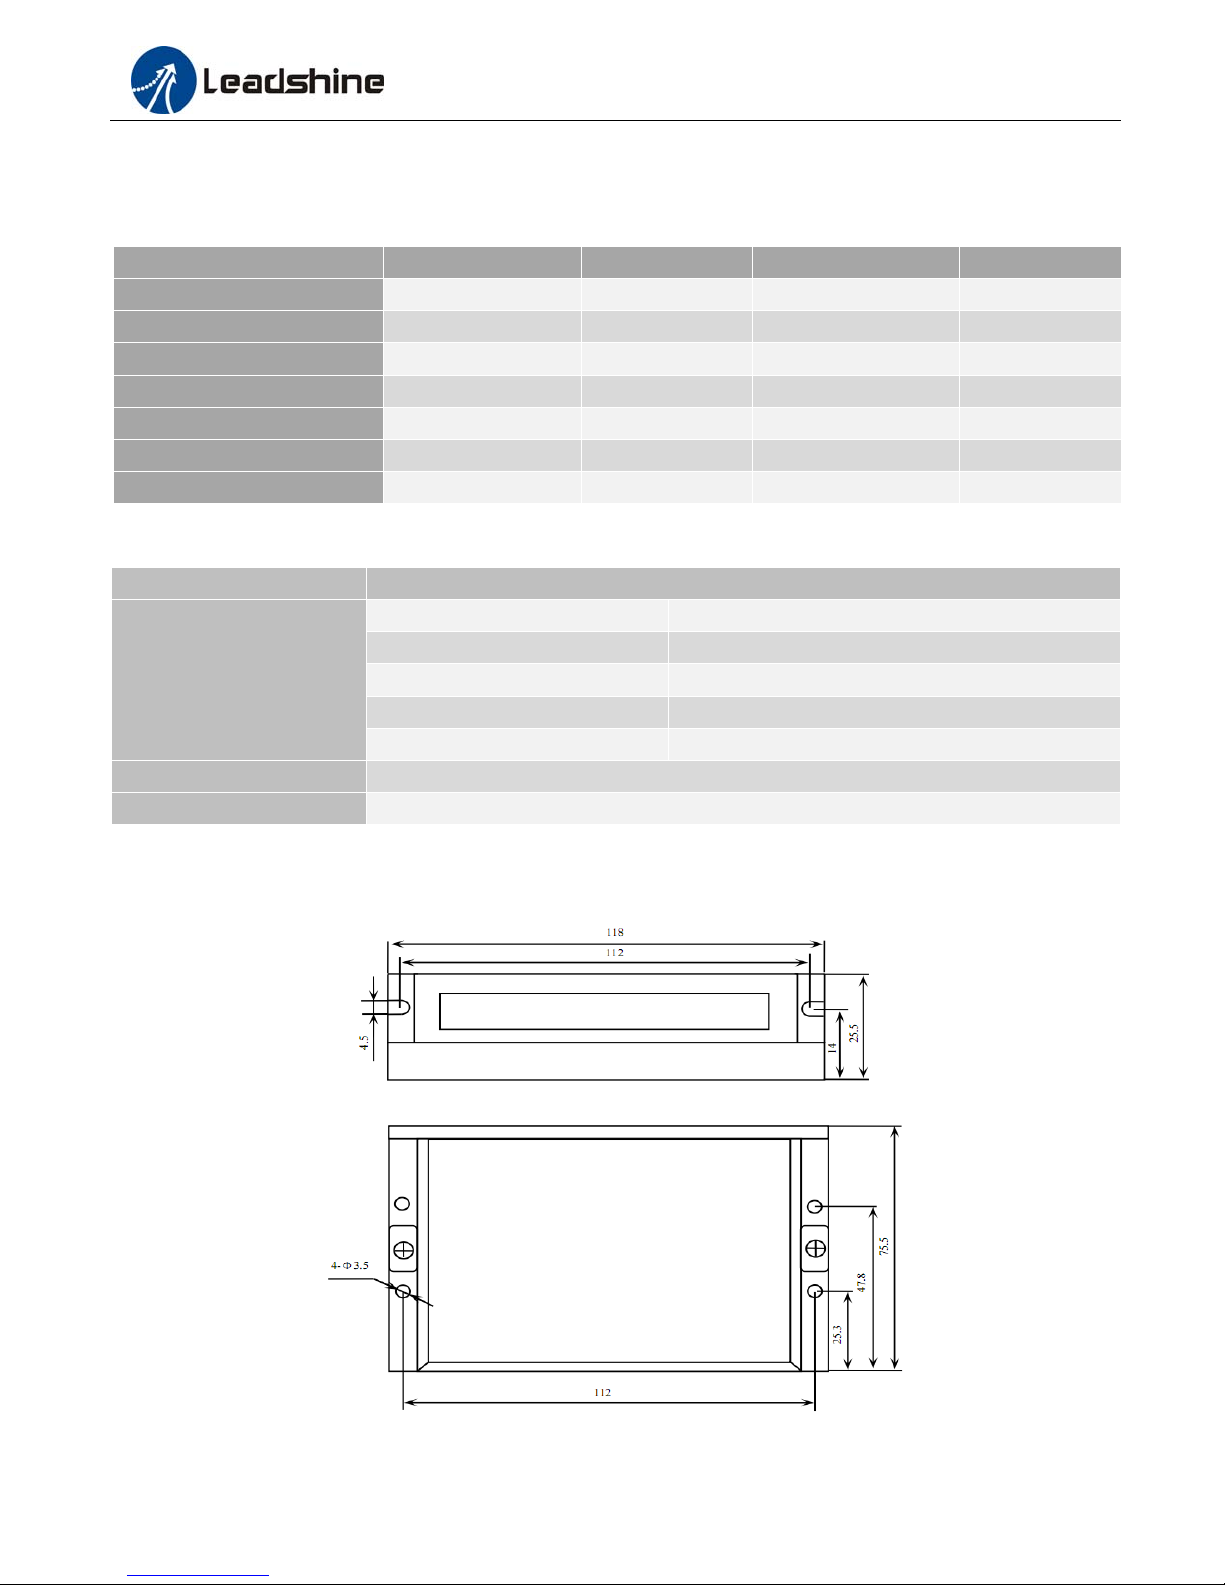
2.1 Electrical Specifications
Parameters Min Typical Max Unit
Output Current 1.0 - 4.2 (3.0 RMS) A
Supply Voltage 20 24 - 48 50 VDC
Logic signal current 7 10 16 mA
Pulse input frequency 0 - 200 kHz
Minimal pulse width 2.5 - - μS
Minimal direction setup 5.0 - - μS
Isolation resistance 500 - - MΩ
2.2 Environment
Cooling Natural Cooling or Forced cooling
Environment
Ambient Temperature
Operating Environment
Humidity
Operating Temperature
Vibration
Storage Temperature -20°C - 65°C (-4°F - 149°F)
Weight Approx. 230g (8 oz)
Avoid dust, oil fog and corrosive gases
0 - 65°C (32 - 149°F)
40 - 90%RH
0 - 50°C (32 - 122°F)
10-50Hz / 0.15mm
2.3 Mechanical Specifications
(unit: mm [1inch=25.4mm])
Figure 1 Mechanical specifications
* Side mounting recommended for better heat dissipation
Page | 2
Page 7
EM542S Digital Stepper Drive User Manual
2.4 Elimination of Heat
EM542S’s working temperature is less than 60Ԩ (140°F)
It is recommended to use automatic idle-current mode to reduce motor heating. That means set the SW4 pin of
DIP switch at “OFF” position.
It is recommended to mount the drive vertically to maximize heat sink area. Use forced cooling method to cool if
necessary.
3. Connection Pin Assignments and LED Indication
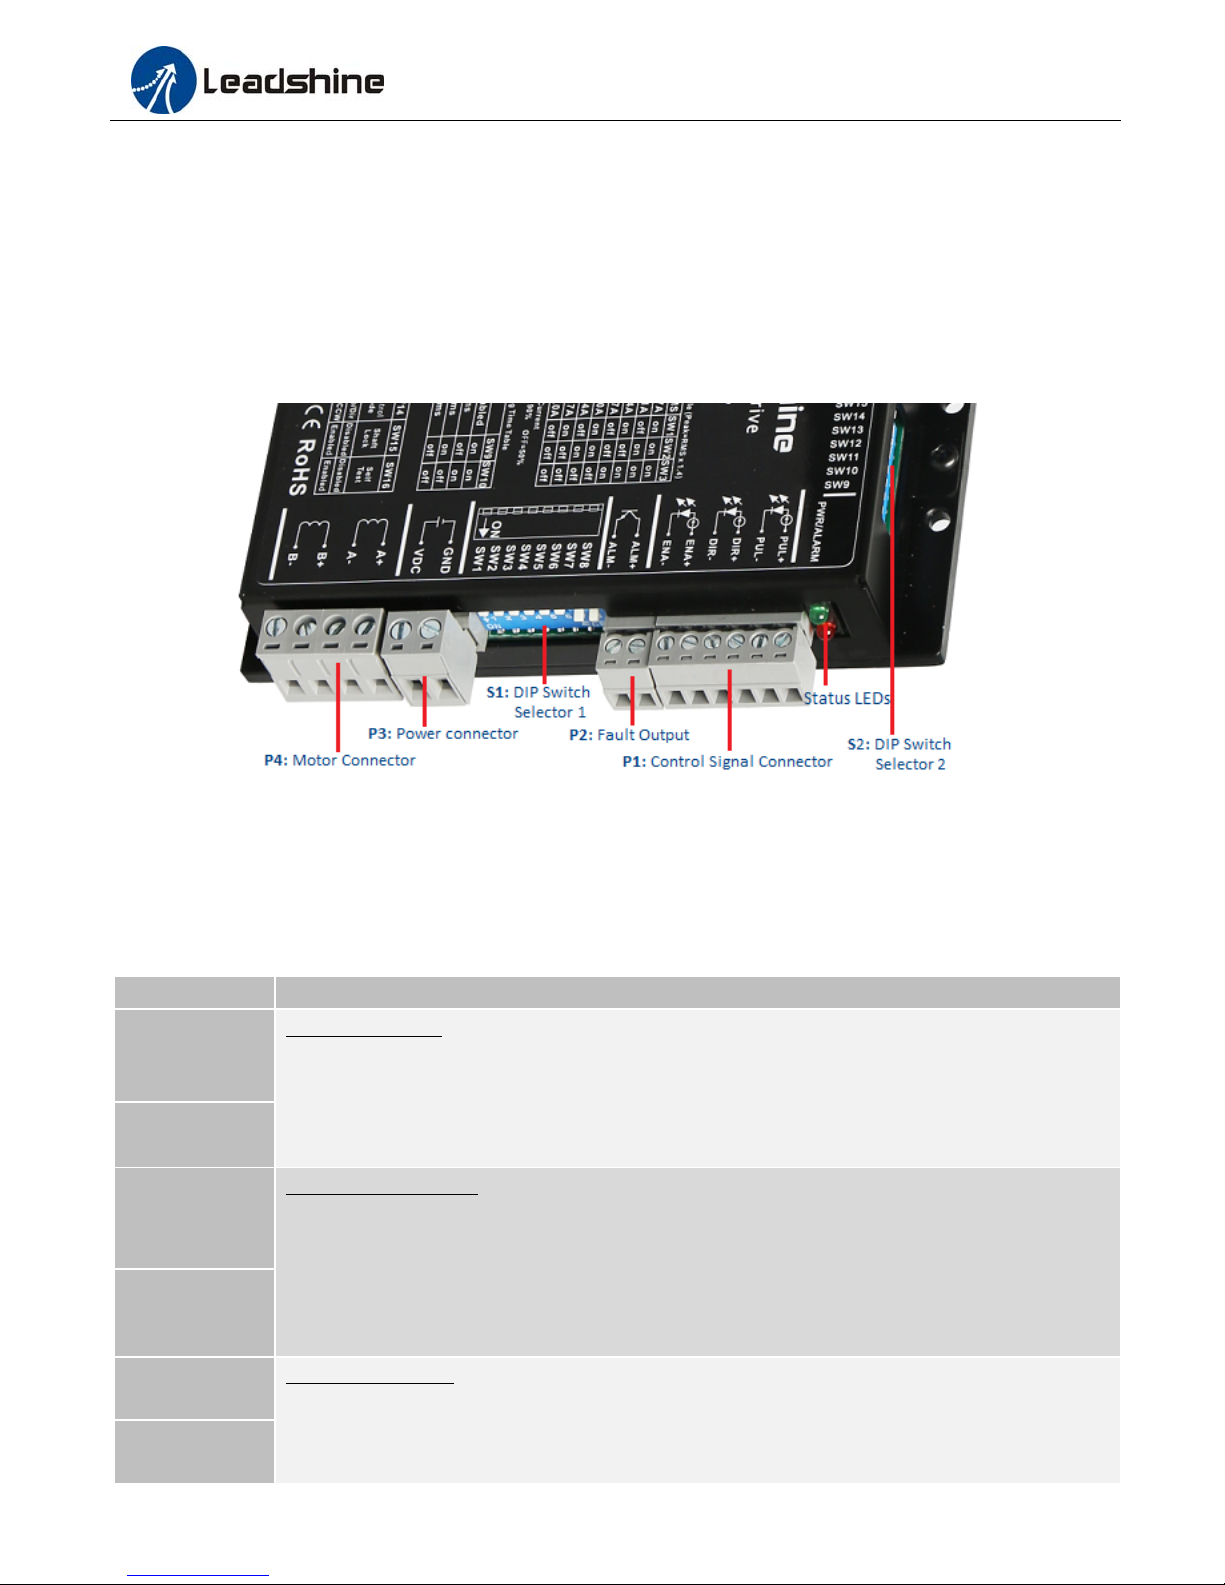
Figure 2 Connectors, DIP switches, and LED locations
The EM542S has four terminal block connectors P1, P2, P3 & P4 (see above picture), and two DIP switch selectors S1
& S2. P1 is for control signal connections, P2 is for fault output, P3 is for power connection, and P4 is for motor
connection.
3.1 P1 - Control Connector Configurations
PIN Details
Pulse Connection: Required. (1) 5-24V, optically isolated, differential. (2) Maximum 200 KHz
PUL+
input frequency. (3) Pulse width of 2.5μs or longer. (4) In single pulse (step & direction) control
mode, this input signal represents a pulse which is active at the rising or falling voltage edge (set
PUL-
by DIP switch SW13); in double pulse (CW/CCW) control mode, this input signal represents
clockwise (CW) pulse which is active at both high voltage level and low voltage level.
Direction Connection: Required. (1) 5-24V, optically isolated, differential. (2) Maximum 200
DIR+
KHz input frequency. (3) Pulse width of 2.5μs or longer. (4) Minimal DIR signal setup time
should be at least 5μs. (5) In single pulse (step & direction) control mode, this signal represents
controls motion rotation direction; in double pulse (CW/CCW) control mode, this input signal
DIR-
controls counterclockwise (CCW) rotation direction and is active at both voltage high level and
low level.
ENA+
Enable Connection: Optional. (1) Optically isolated, differential. (2) Disable the drive by 5-24V
input connection; enable the drive by 0-0.5 VDC connection. (3) This connection is optional
(defaulted to unconnected) with drive enabled. (4) By default, motor shaft is unlocked when drive
ENA-
disabled but can be configured to shaft locked by DIP switch SW15.
Page | 3
Page 8
EM542S Digital Stepper Drive User Manual
!
Notice
Notes: to avoid interference: (1) shield control signal wires; (2) don’t tie PUL/DIR control signal cable and motor
wires together;
3.2 P2 - Fault Output Connector
Pin Details
ALM+
Fault Output Connection: Optional. (1) Maximum 24V/80mA output when over-voltage and
over-current error protections activated. (2) Sinking or sourcing. (3) The resistance between
ALM+ and ALM- is low impedance as default (configurable by DIP switch SW12), and will
ALM-
change to high when the drive goes into error protection.
3.3 P3 - Power Connector
Pin Details
GND Connect to power supply ground connection.
+VDC Connect to power supply positive connection. Suggest 24-48VDC power supply voltage
!
Warning
Warning: Don’t plug/unplug P3 or any P1/P2/P4 terminal block to avoid drive damage or injury while powered on.
3.3 P4 - Motor Connector
PIN Details
A+ Connect to motor A+ wire
A- Connect to motor A- wire
B+ Connect to motor B+ wire
B- Connect to motor B- wire
3.5 Status LED Lights
There are two LED lights for EM542S. The GREEN one is the power indicator which should be always on in normal
circumstance. The RED one is a drive status indication light, which will be OFF while working normally but ON and
flash 1-2 times in a 3-second period in the case of enabled over-voltage or over-current protection.
4. Control Signal and Fault Output
4.1 Control Signal Connection
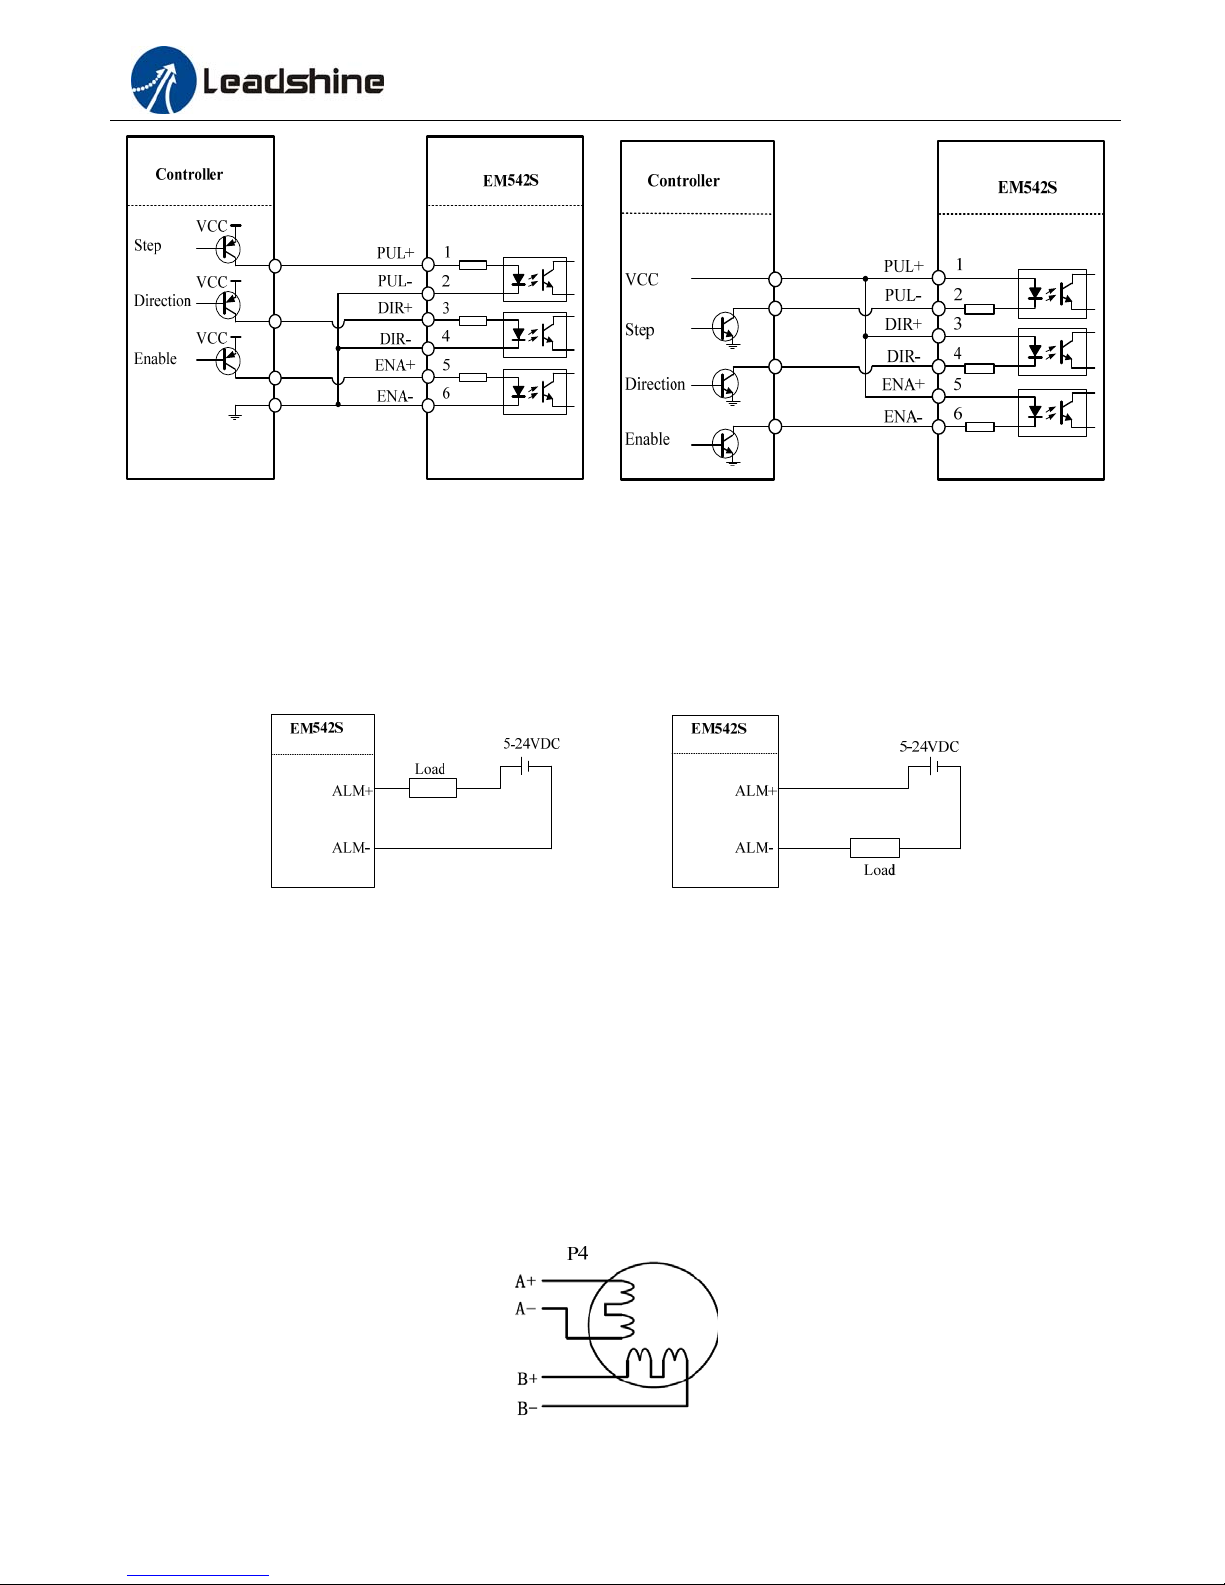
The EM542S can accept differential or single-ended control signals (pulse, direction, and enable) in open-collector or
PNP connection through the P1 connector (figure 2). It is recommend to add an EMI line filter between the power
supply and the drive to increase noise immunity for the drive in interference environments.
Page | 4
Page 9
EM542S Digital Stepper Drive User Manual
Figure 3 Connections to open-collector signals Figure 4 Connections to PNP signals
(Common-anode) (Common-cathode)
4.2 Fault output connection
When over voltage or over current protection happens, EM542S red status LED light will blink and the impedance
state between ALM+ and ALM- will change (from low to high or high to low depending on configuration) and can thus
be detected. Fault output connection is optional, and it can be connected either in sinking or sourcing.
Figure 5 Sinking output Figure 6 Sourcing output
5. Stepper Motor Connections
EM542S can drive 2-phase and 4-phase bipolar hybrid stepper motors with 4, 6, or 8 wires. Although setting the output
current to 1.4 times of motor phase current will get maximum torque from the motor, at the same time motor heating
will be also maximized. So, just configure the drive output current to a value which will get sufficient torque to reduce
motor heating.
5.1 4-lead Motor Connection
Refer to figure 7 for how to connect a 4-wire stepper motor. Configure EM542S output current to one of the 8 available
values through DIP switches SW 1-3 of the DIP switch selector 1 (figure 2).
Figure 7 4-lead Motor Connection
Page | 5
Page 10
EM542S Digital Stepper Drive User Manual
5.2 6-lead Motor Connection
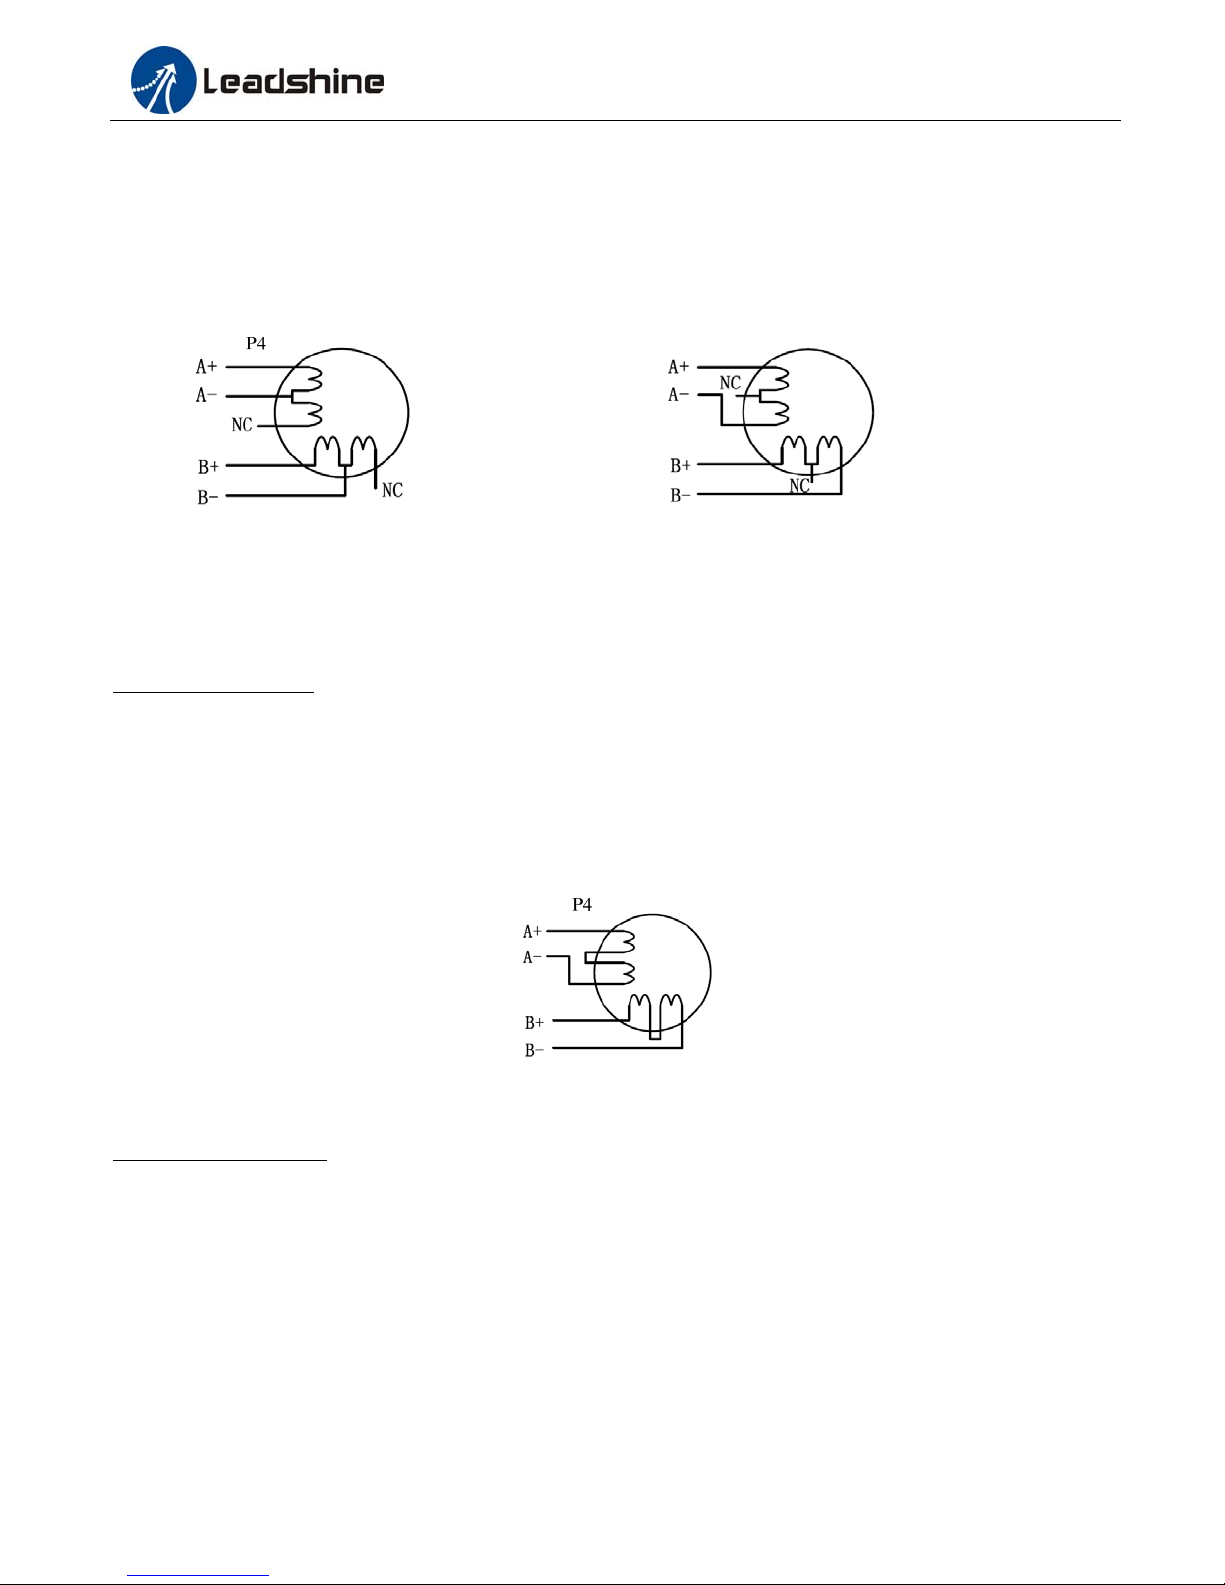
EM542S can power 6-lead stepper motors through half coil connection (half chopper) or full coil (full copper)
connection. The half coil connection only uses one half of the motor’s windings and is usually selected in applications
requiring high speed but lower torque. The full coil connection uses the full coil windings and is usually selected in
high-torque required applications. Refer to figure 7 and 8 for those two connections.
P4
Figure 8 6-lead motor half coil connection Figure 9 6-lead motor full coil connection
5.3 8-lead Motor Connection
EM542S can power 8-lead in series or parallel connection in series or parallel.
5.3.1 Series Connection
Series connected 8-lead stepper motors are typically implemented in applications which higher torque at lower speed
movement is required. Because a stepper motors under series connection has the most inductance, the performance will
start to degrade when the motor runs at higher speed. For this connection, it is suggested to set an EM542S’s output
RMA current to no more than 70% of the stepper motor’s phase current to prevent overheating. See the next figure for
how to connect an 8-lead stepper motor for series connection.
Figure 10 8-lead motor series connection
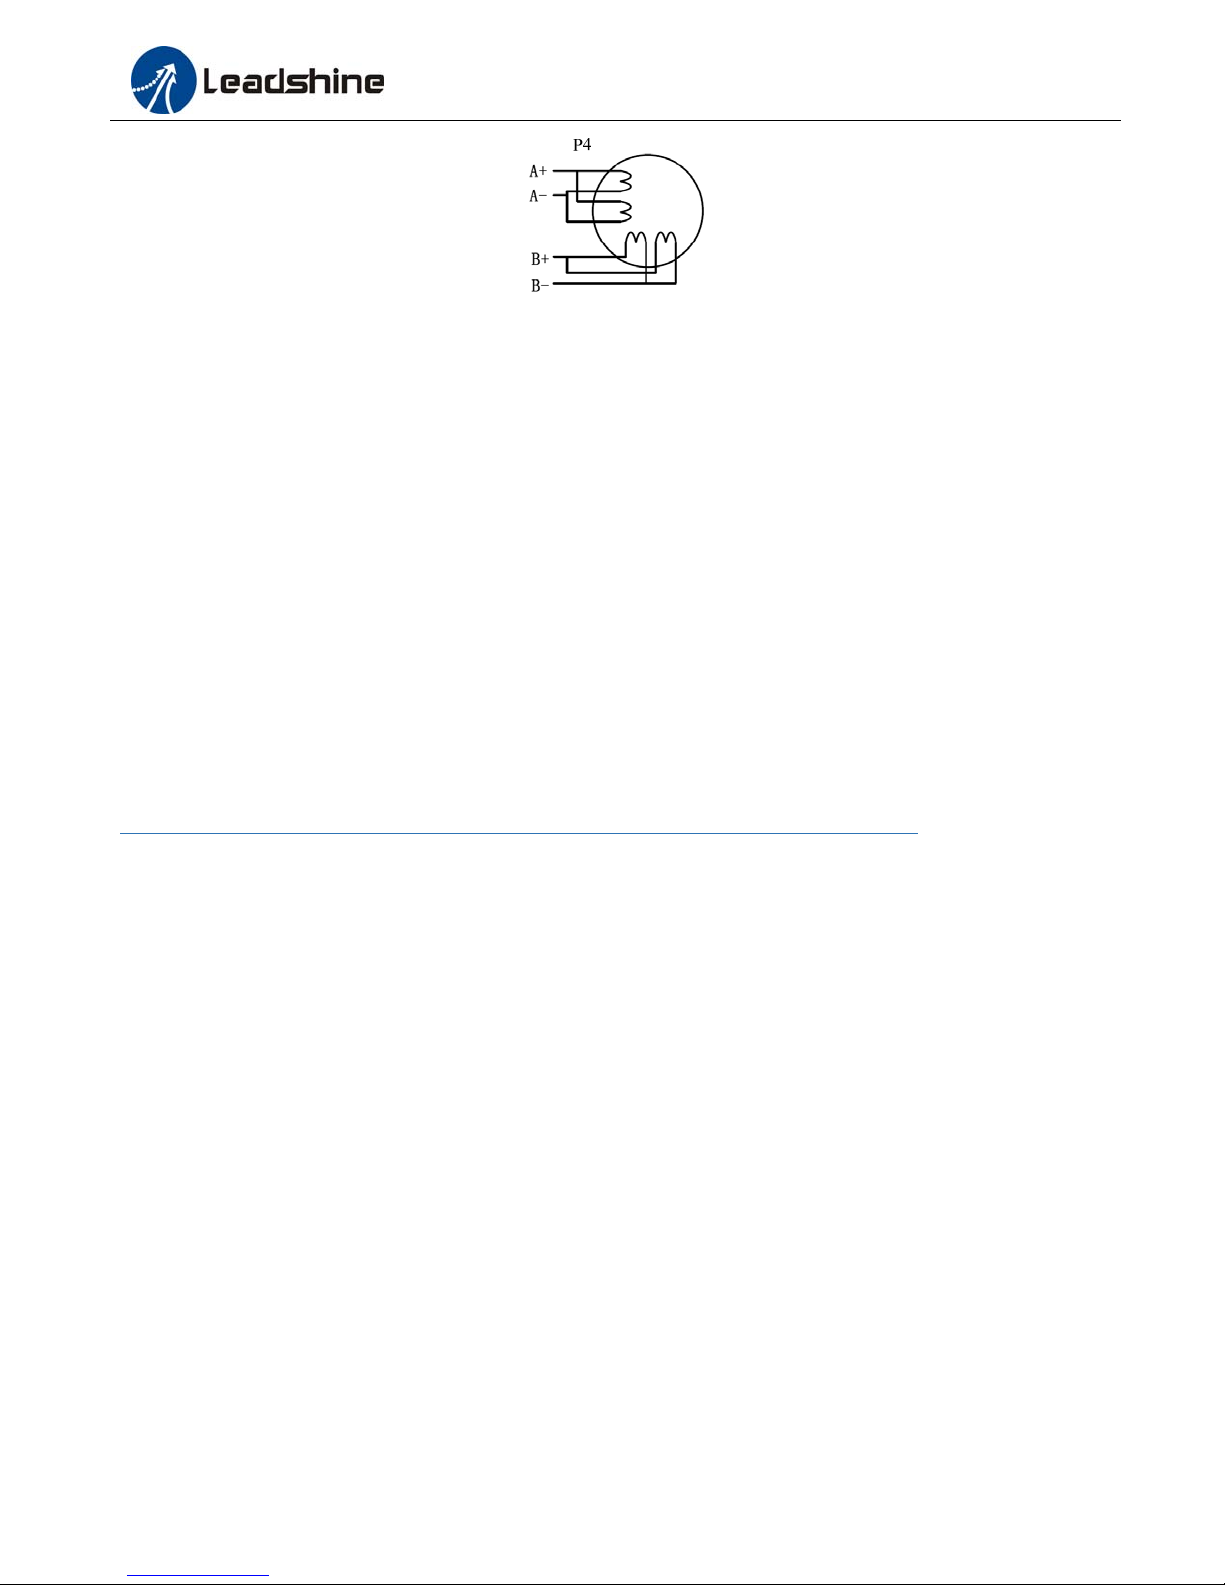
5.3.2 Parallel Connection
Parallel connected 8-lead stepper motors are typically implemented in applications which higher torque at high speed
movement is required. Compared with series connection, a parallel connected stepper motor has lower inductance and
therefore have better torque performance at higher speed movement. Although setting the drive output current to 1.4
times of driven motor phase current will get the most torque, it is suggested to set an EM542S’s output current (peak of
sinusoidal) to no more than 1.2 times the stepper motor’s phase current to prevent overheating. Refer to the next figure
for how to connect an 8-lead stepper motor for parallel connection.
Page | 6
Page 11
EM542S Digital Stepper Drive User Manual
Figure 11 8-lead motor parallel connection
6. Power Supply Selection
EM542S is designed to power small and medium size stepping motors (frame sizes NEMA17 to 24) made by
Leadshine or other motor manufacturers. To get optimal performances, it is important to select proper power supply
type, voltage, and supply output current. In general power supply voltage determines the high speed performance of a
stepper motor, while drive output current determines the driven motor torque output. Higher supply voltage can
increases motor speed torque performance, but at the same time result in more noise and motor heating. For low motor
speed applications, it is suggested to use lower supply voltage power supplies.
6.1 Regulated or Unregulated Power Supply
Both regulated and unregulated power supplies can be used to power an EM542. Theoretically unregulated power
supplies are preferred due to their ability to withstand back EMF current surge and faster response for current change.
If you prefer to use a regulated power supply instead, it is suggested to choose one specially designed for stepper or
servo controls such as one Leadshine RPS series power supply
(http://www.leadshine.com/ProductSubType.aspx?subtype=regulated-switching-power-supplies). In the case when
only general purpose switching power supplies are available, choose one with “OVERSIZED” current output rating
(for example, using a 4A power supply for 3A stepper motor) to avoid current clamp. On the other hand, if unregulated
supply is used, one may use a power supply of lower current rating than that of motor (typically 50%~70% of motor
phase current). The reason is that the drive only draws current from an unregulated power supply during the ON
duration of the PWM cycle, but not during the OFF duration.
6.2 Power Supply Sharing
Multiple EM542S drives can share the same power supply, if that power supply has enough capacity. To avoid cross
interference, connect each EM542S DIRECTLY to that shared power supply separately instead of connecting those
power connectors of drives in daisy-chain connection.
6.3 Selecting Supply Voltage
EM542S’s operating voltage is 20–50 VDC. Because of voltage increasing from potential power line voltage
fluctuation and back EMF voltage generated during motor deceleration, it is suggested to use a 24-48 VDC power
supply.
7. DIP Switch Configurations
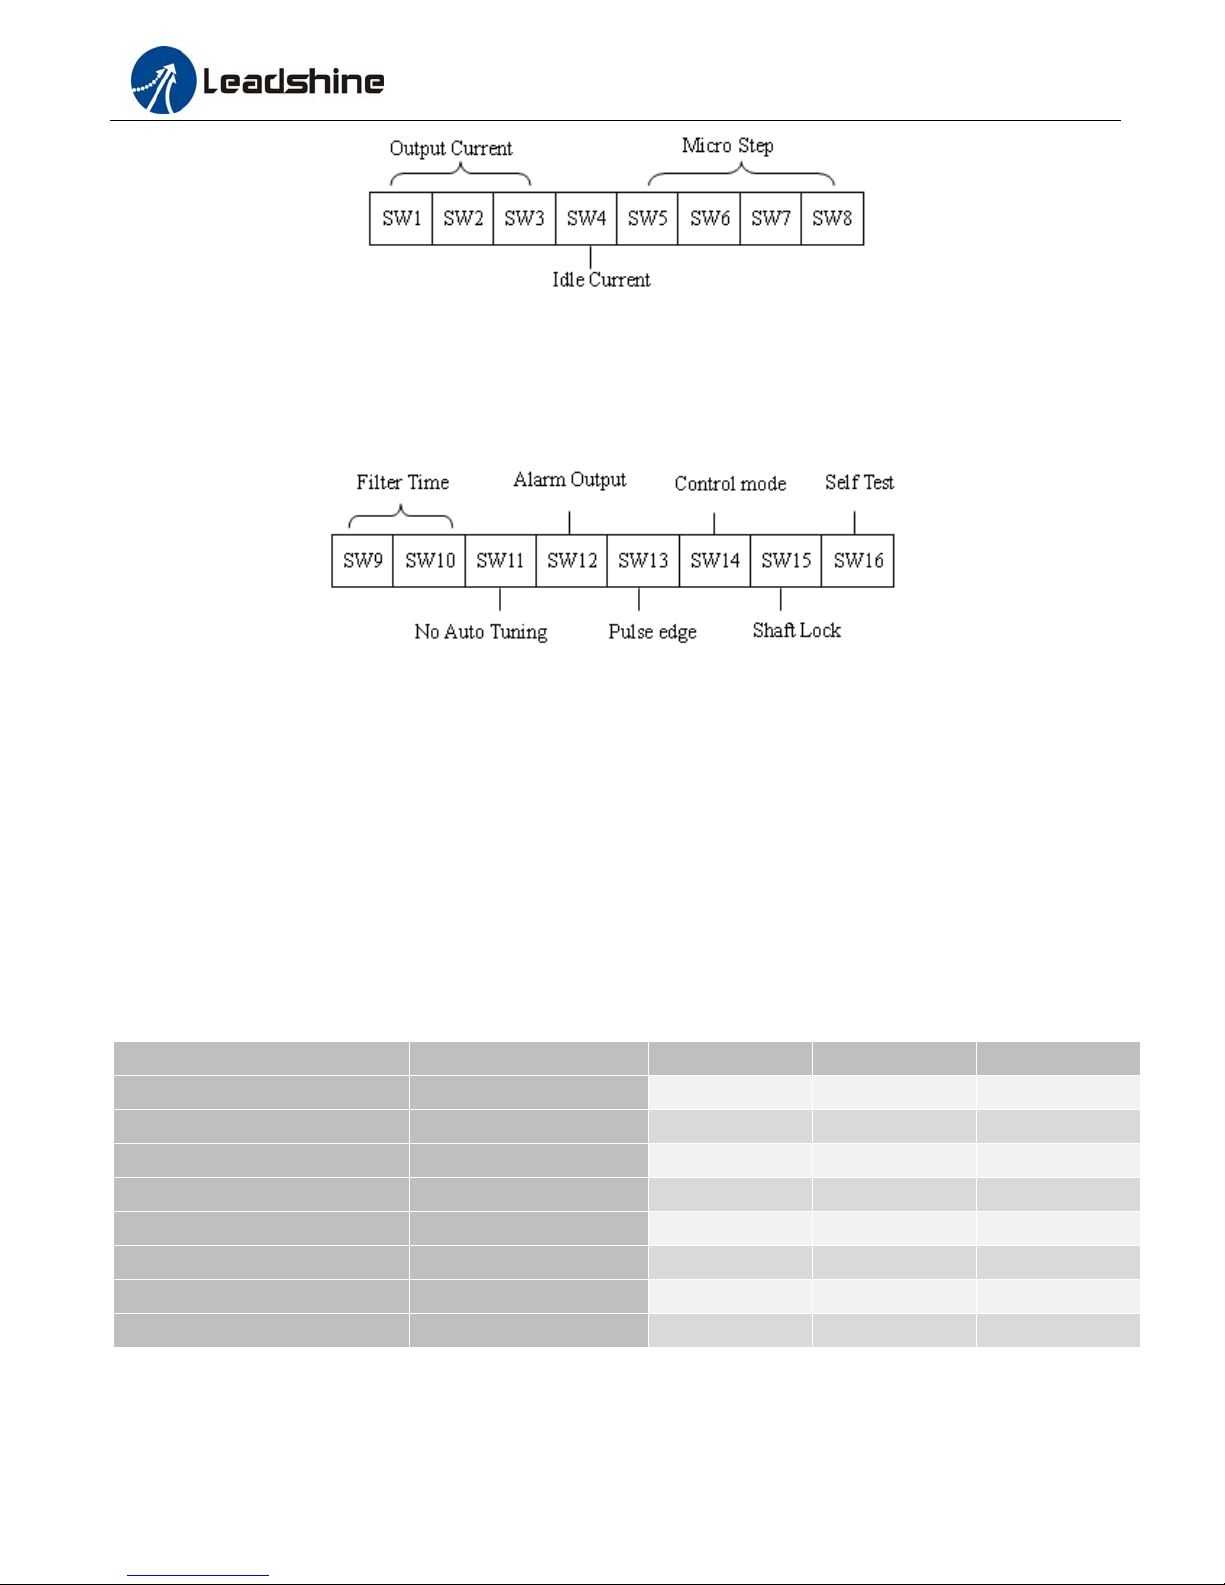
Each EM542 has two 2-bit DIP switch selectors. The first one is located on the side (DIP switch selector 1 in Figure 2)
and used to configure settings of micro step resolution, output current, and motor standstill current as shown below:
Page | 7
Page 12
EM542S Digital Stepper Drive User Manual
The second 8-bit DIP switch is located on the top (DIP switch selector 2 in figure 2), and used to configure settings of
control command filtering time, motor auto-configuration, fault output impedance, pulse active edge, control mode,
lock shaft, and self-test as shown below:
7.1 Output Current Configuration (SW1-3)
The EM542S has 8 micro step settings which can be configured through DIP switch SW1, SW2 and SW3.
For a given stepper motor, higher drive output current will make it output higher torque, but at the same time cause
more heating for both the motor and drive. Therefore, output current is generally set to be such that the motor will not
overheat for long time operation. Since parallel and serial connections of motor coils will significantly change resulting
inductance and resistance, it is therefore important to set drive output current depending on motor phase current, motor
leads and connection methods. Phase current rating supplied by motor manufacturer is important in selecting drive
current; however the selection also depends on leads and connections.
The first three bits (SW1, 2, 3) of the DIP switch are used to set the dynamic current. Select a setting closest to your
motor’s required current.
Peak Current RMS Current SW1 SW2 SW3
1.00A 0.71A ON ON ON
1.46A 1.04A OFF ON ON
1.91A 1.36A ON OFF ON
2.37A 1.69A OFF OFF ON
2.84A 2.03A ON ON OFF
3.31A 2.36A OFF ON OFF
3.76A 2.69A ON OFF OFF
4.20A 3.00A (default) OFF OFF OFF
7.2 Idle Current Configuration (SW4)
The SW4 of an EM542S is used to set output current percentage when motor is standstill. Idle current percentage will
be set to 50% at OFF position, and 90% at ON position. When the driven stepper motor is idle (no movement) for 0.4
Page | 8
Page 13
EM542S Digital Stepper Drive User Manual
second, the output current of EM542S will be automatically reduced to the configured percentage.
7.3 Micro Step Configuration (SW5-8)
Each EM542S has 16 micro step settings which can be configured through DIP switch SW5, SW6, SW7, and SW8.
See the following table for detail.
Micro step Pulses/Rev. (for 1.8°motor) SW5 SW6 SW7 SW8
1 200 ON ON ON ON
2 400 OFF ON ON ON
4 800 ON OFF ON ON
8 1600 (default) OFF OFF ON ON
16 3200 ON ON OFF ON
32 6400 OFF ON OFF ON
64 12800 ON OFF OFF ON
128 25600 OFF OFF OFF ON
5 1000 ON ON ON OFF
10 2000 OFF ON ON OFF
20
4000 ON OFF
ON
OFF
25 5000 OFF OFF ON OFF
40 8000 ON ON OFF OFF
50 10000 OFF ON OFF OFF
100 20000 ON OFF OFF OFF
125 25000 OFF OFF OFF OFF
7.4 Filter Time Configuration (SW9-10)
EM542S has an advanced feature called control command smoothing to eliminate “noise” input pulse from the pulse
generator (controller, PLC, etc.), and therefore improve motion smoothness and high-speed torque performance in
many circumstances.
This is achieved through adding filtering time which is configured SW 9-10. See the following table for how to
configure. In multi-axis applications make sure to set the Filter Time value of each EM542 to the same.
Filter Time SW9 SW10
0 ms (disabled) ON ON
6 ms OFF ON
12 ms ON OFF
25 ms (default) OFF OFF
!
Warning
The Filter Time value must be set to the same for each EM542S in multi-axis applications
7.5 No Auto Tuning Configuration (SW11)
EM542S can configure itself with the best match to the driven stepper motor for optimal performance. This feature
Page | 9
Page 14
EM542S Digital Stepper Drive User Manual
may need to be disabled for some applications or when it is used to drive a specially designed stepper motor. To do that,
set the DIP switch SW11 to ON position and the drive will be set to its default settings.
7.6 Alarm Output Configuration (SW12)
DIP switch SW12 is used to configure the impedance state of alarm output (fault output). At OFF position (default) the
resistance between ALM+ and ALM- is set to low impedance in normal operation, and will change to high impedance
when the drive goes into over-voltage or over-current protection. When SW12 is set to ON position, that resistance will
be set to high impedance in normal condition and changed to low impedance under error protections.
7.7 Pulse Edge Configuration (SW13)
DIP switch SW13 is used to configure which voltage edge will activate a pulse signal. Set it to OFF position (default)
means that a pulse is activated at voltage rising edge, and ON position means a pulse is activated at falling edge. Make
sure this setting will match the pulse generator (controller, PLC, etc.)
7.8 Control Mode Configuration (SW14)
DIP switch SW14 is used to configure the control mode of EM542S. By default it is set to OFF position for single
pulse (step & direction, or pulse & direction) control. To change the control model to double pulse (CW/CCW) control
type, set its position to OFF.
7.9 Shaft Lock Configuration (SW15)
Use DIP switch SW15 to set shaft lock mode when EM542 is disabled (read ENA+ and ENA- explanation of control
connector for how to disable EM542S). Set it to OFF position (default) for no motor shaft lock (free spin) when drive
disabled. Set it to ON position for motor shaft lock.
7.10 Self-Test Configuration (SW16)
For test and system diagnosis purpose, EM42 is featured with Self-Test. Anytime DIP switch SW16 is switched to ON
position, the drive will automatically rotate the driven stepper motor back and forth for one round in each direction. Set
this switch position to OFF for normal operation.
8. Wiring Notes
In order to improve anti-interference performance of the drive, it is recommended to use twisted pair shield cable.
To prevent noise incurred in PUL/DIR signal, pulse/direction signal wires and motor wires should not be tied up
together. It is better to separate them by at least 10 cm; otherwise the disturbing signals generated by motor will
easily disturb pulse direction signals, causing motor position error, system instability and other failures.
If only one power supply serves multiple EM542S drives, separately connecting the drives to the power supply is
recommended instead of daisy-chaining.
It is prohibited to pull and plug connector P4 while the drive is powered ON, because there is high current flowing
through motor coils (even when motor is at standstill). Pulling or plugging connector P4 with power on will cause
extremely high back-EMF voltage surge, which may damage the drive.
Page | 10
Page 15
EM542S Digital Stepper Drive User Manual
9. Typical Connection
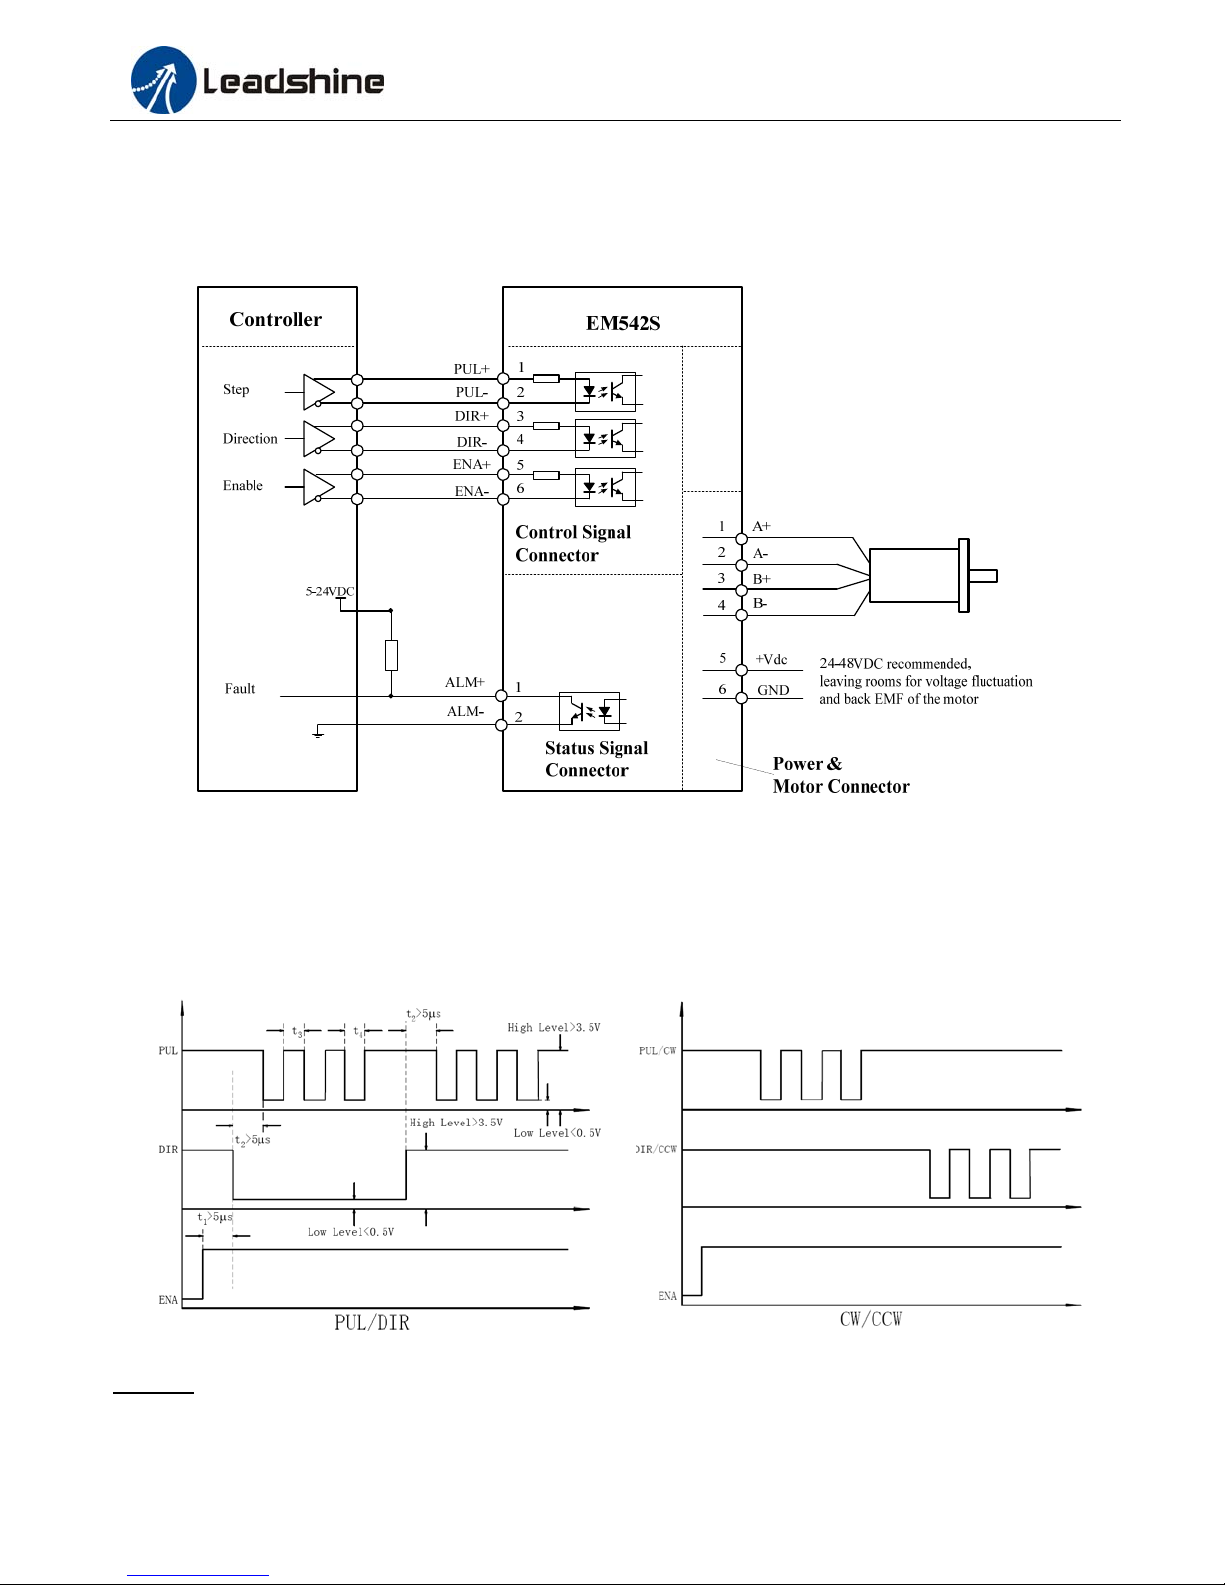
A complete stepping system should include stepping motor, stepping drive, power supply and controller (pulse
generator). A typical connection is shown as figure 11.
Figure 12 Typical connection
10. Sequence Chart of Control Signals
In order to avoid some fault operations and deviations, PUL, DIR and ENA should abide by some rules, shown as
following diagram:
Figure 13 Sequence chart of control signals
Remark:
a) t1: ENA must be ahead of DIR by at least 5s. Usually, ENA+ and ENA- are NC (not connected). See
“Connector P1 Configurations” for more information.
b) t2: DIR must be ahead of PUL effective edge by 5s to ensure correct direction;
Page | 11
Page 16
EM542S Digital Stepper Drive User Manual
c) t3: Pulse width not less than 2.5s;
d) t4: Low level width not less than 2.5s.
11. Protection Functions
EM542S incorporates are built with over-voltage and over-current error protections. When it is under error
protection, the red LED light will blink for one or two times in a period of 3 seconds. If fault output connection is
connected, the impedance mode between ALM+ and ALM- will be changed (See “Fault Output Configuration”
section for detail).
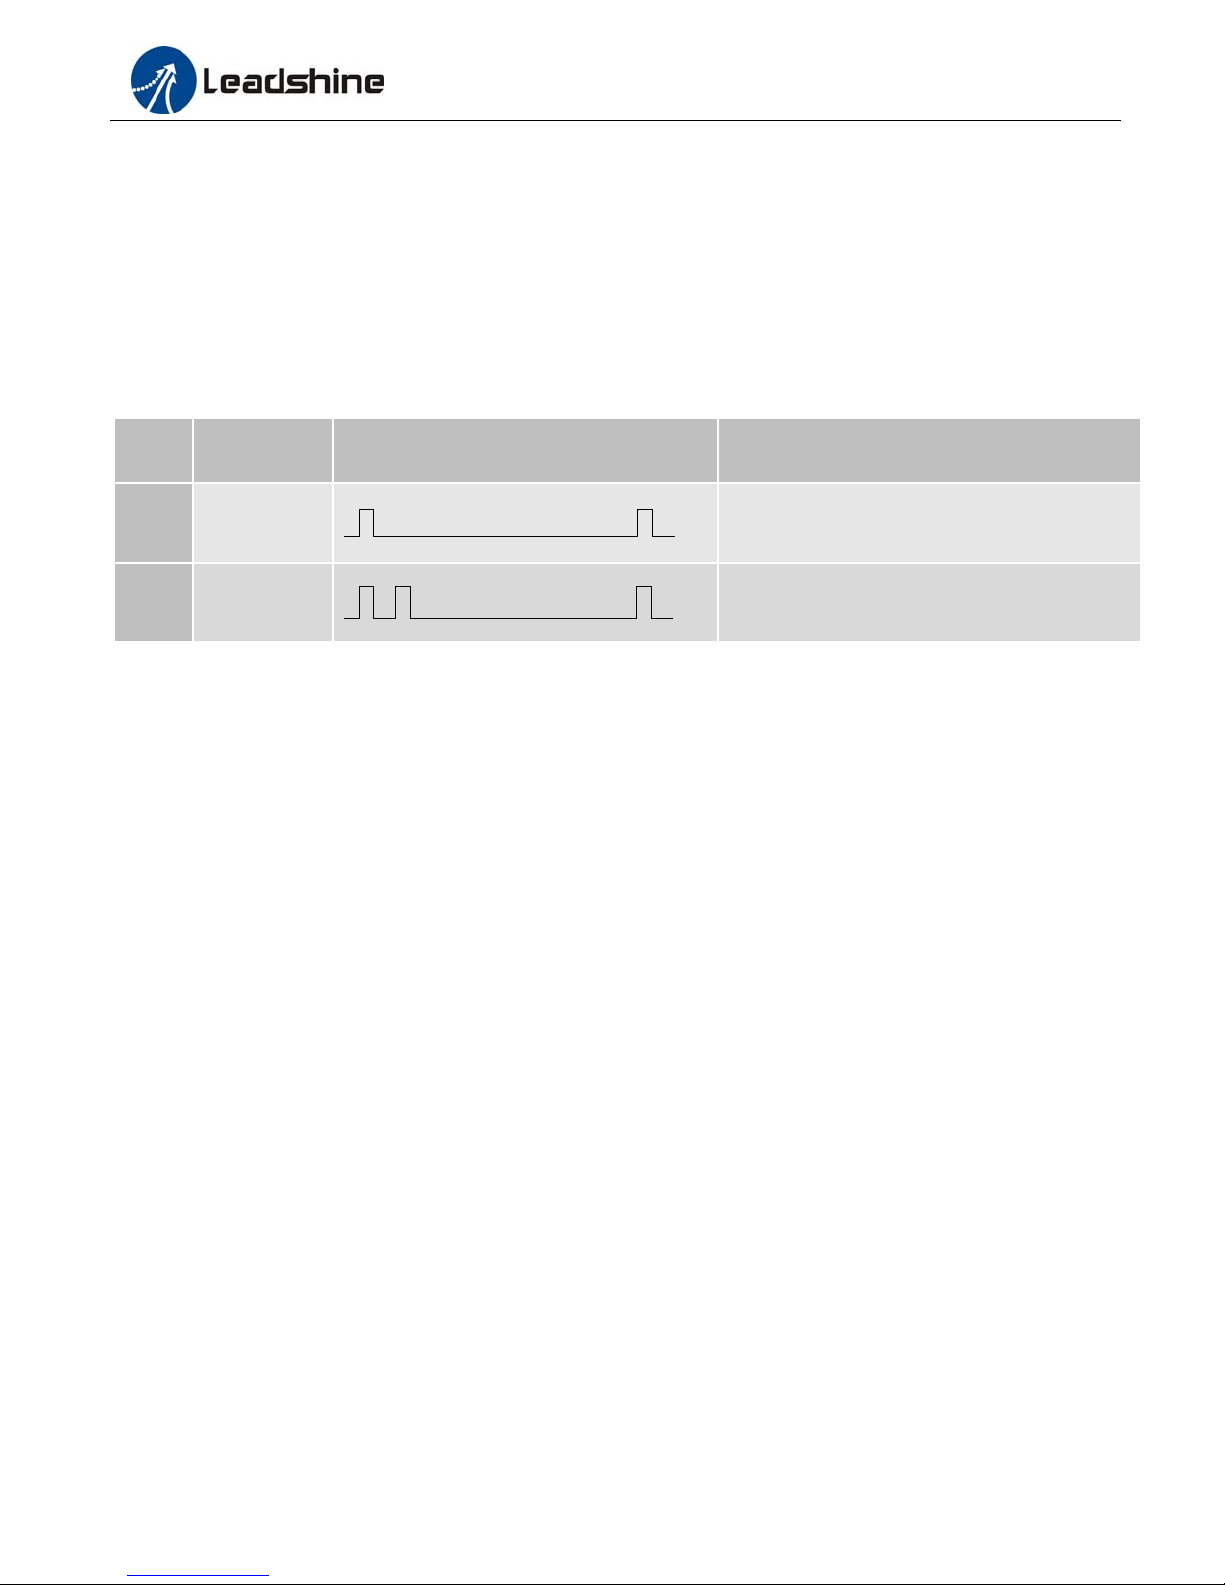
Priority
1st
2nd
Time(s) of
Blink
1
2
Sequence wave of red LED Description
Over-current protection activated when peak
current exceeds the limit.
Over-voltage protection activated when drive
working voltage is greater than 60VDC
Figure 14 Error Protections
When above protections are active, the motor shaft will be free or the red LED blinks. Reset the drive by repowering it
to make it function properly after removing above problems.
Page | 12
Page 17
EM542S Digital Stepper Drive User Manual
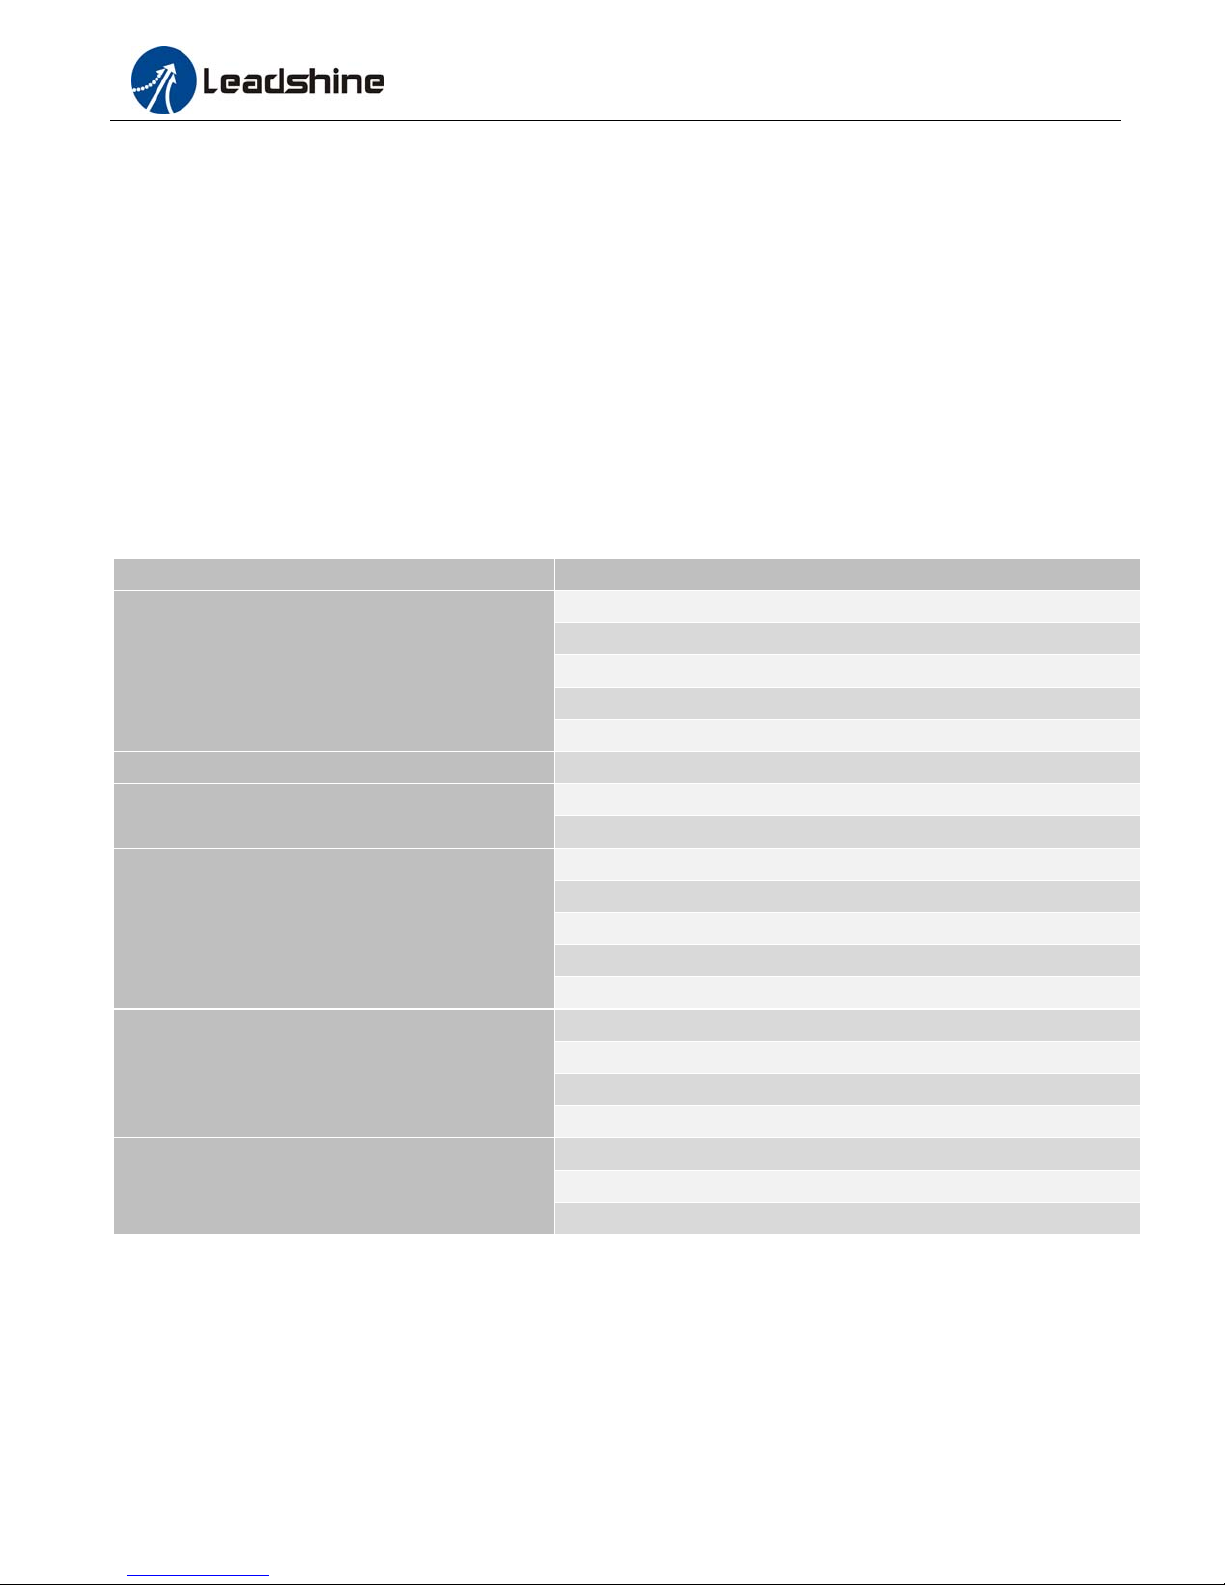
12. Troubleshooting
In the event that your drive doesn’t operate properly, the first step is to identify whether the problem is electrical or
mechanical in nature. The next step is to isolate the system component that is causing the problem. As part of this
process you may have to disconnect the individual components that make up your system and verify that they operate
independently. It is important to document each step in the troubleshooting process. You may need this documentation
to refer back to at a later date, and these details will greatly assist our Technical Support staff in determining the
problem should you need assistance.
Many of the problems that affect motion control systems can be traced to electrical noise, controller software errors, or
mistake in wiring.
Problem Symptoms and Possible Causes
Symptoms Possible Problems
No power
Pulse/revolution setting is wrong
Motor is not rotating
Motor rotates in the wrong direction
The drive in fault
Erratic motor motion
Motor stalls during acceleration
Excessive motor and drive heating
DIP switch current setting is wrong
Fault condition exists
The drive is disabled
Motor phases may be connected in reverse
DIP switch current setting is wrong
Something wrong with motor coil
Control signal is too weak
Control signal is interfered
Wrong motor connection
Something wrong with motor coil
Current setting is too small, losing steps
Current setting is too small
Motor is undersized for the application
Acceleration is set too high
Power supply voltage too low
Inadequate heat sinking / cooling
Automatic current reduction function not being utilized
Current is set too high
Page | 13
Page 18
EM542S Digital Stepper Drive User Manual
13. Warranty
Twelve Month Warranty
Leadshine Technology Co., Ltd. warrants its products against defects in materials and workmanship for a period of 12
months from shipment out of factory. During the warranty period, Leadshine will either, at its option, repair or replace
products which proved to be defective.
Exclusions
The above warranty does not extend to any product damaged by reasons of improper or inadequate handlings by
customer, improper or inadequate customer wirings, unauthorized modification or misuse, or operation beyond the
electrical specifications of the product and/or operation beyond environmental specifications for the product.
Obtaining Warranty Service
To obtain warranty service, please contact your seller to obtain a returned material authorization number (RMA) before
returning product for service.
Shipping Failed Products
If your product fail during the warranty period, please contact your seller for how and where to ship the failed product
for warranty or repair services first, you can also
authorization number (RMA) before returning product for service. Please include a written description of the problem along with contact
name and address.
e-mail customer service at [email protected] to obtain a returned material
Page | 14
Page 19
14. Contact Us
EM542S Digital Stepper Drive User Manual
Leadshine Technology Co., Ltd (Headquarters)
Address: Floor 11, Block A3, Nanshan iPark
1001 Xueyuan Avenue
Nanshan District
Shenzhen, Guangdong, 518055
China
Web: http://www.leadshine.com
Tel: 86-755-2643 4369 (All Regions)
86- 755-2641-7617 (North & South America)
86-755-2641-7674 (Asia, Australia, Africa)
86-755-2640-9254 (Europe)
Fax: 86-755-2640-2718
Email: [email protected]
Leadshine America Inc.
Address: 26050 Towne Centre Dr.
Foothill Ranch, CA 92610
USA
Tel: 1-949-608-7270
Fax: 1-949-608-7298
Web: http://www.leadshineusa.com
Email: [email protected] (Sales)
[email protected] (Support)
Page | 15
 Loading...