

Page 1
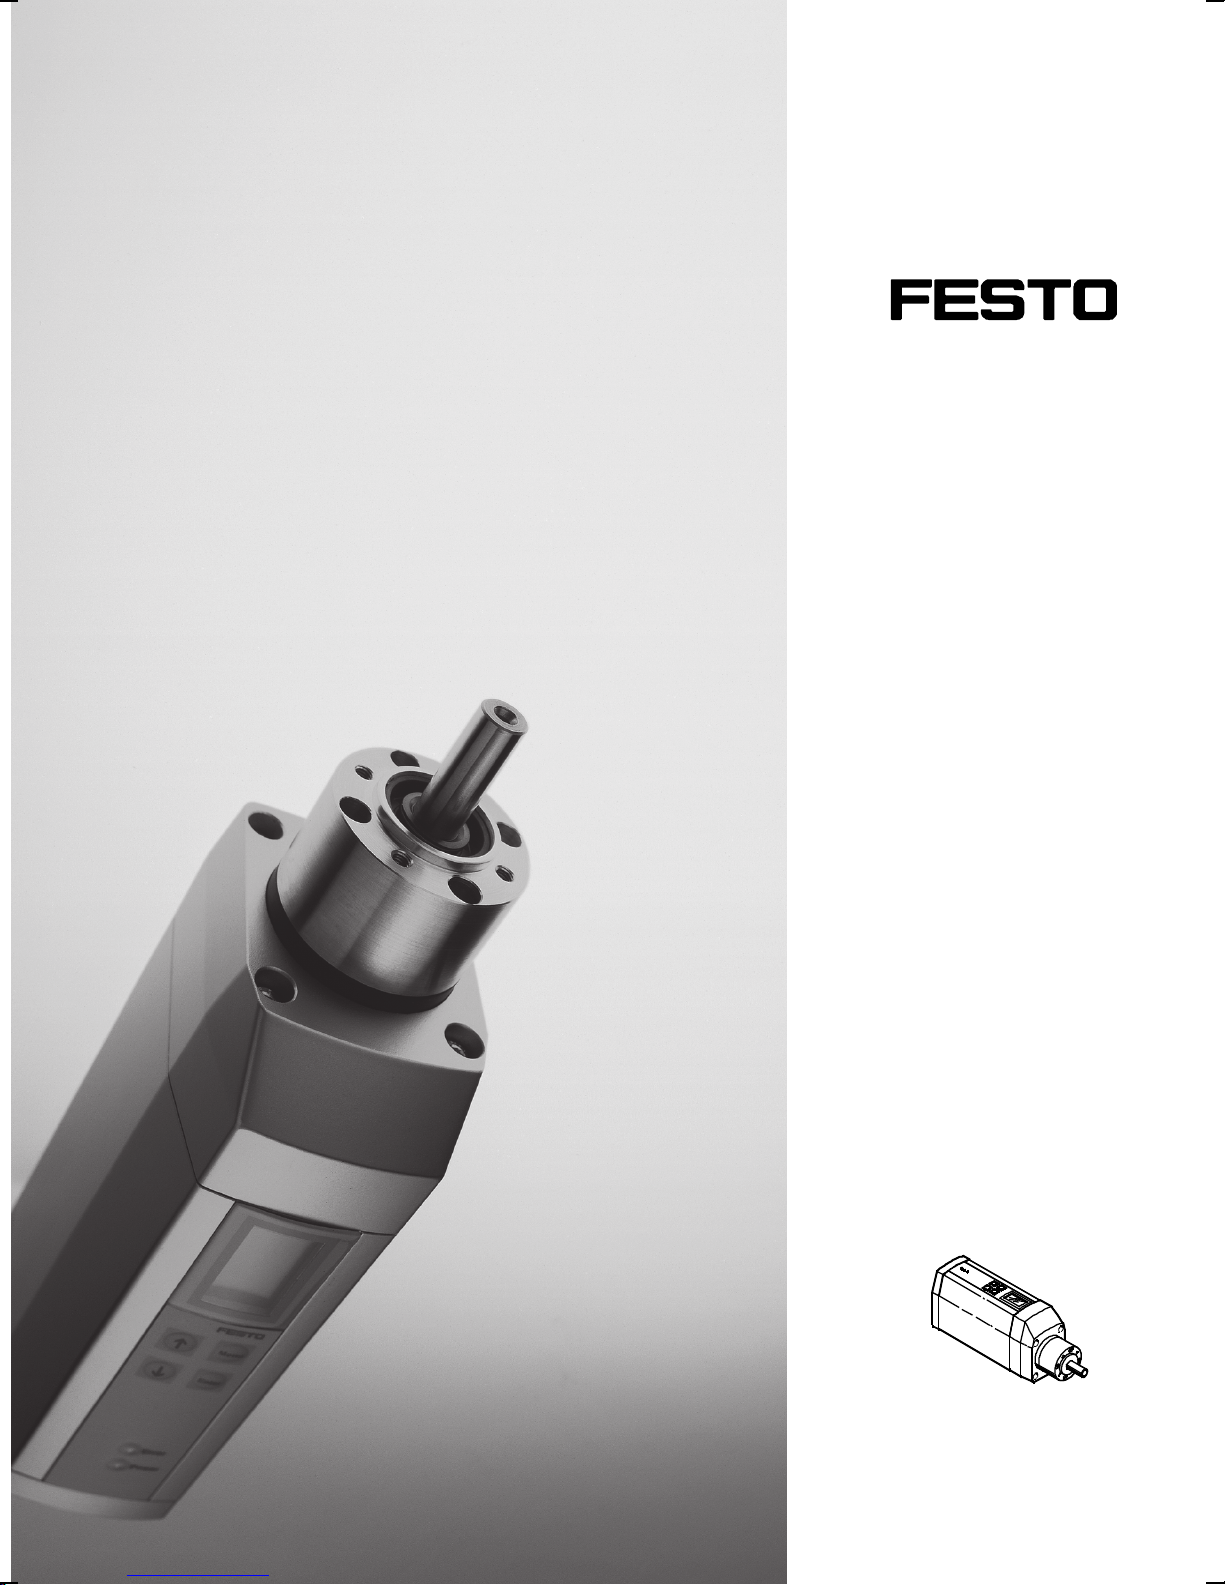
Motor unit
MTR-DCI
Description
MTR-DCI-...IO
Description
539616
en 1209d
[763197]
Page 2
Adobe®,Reader®,CANopen®and CiA®are registered
trademarks of the respective trademark owners in certain
countries.
Page 3
Contents and general instructions
Original de.......................................
Edition en 1209d..................................
Designation P.BE-MTR-DCI-IO-EN.....................
Order no. 539616..................................
© (Festo AG & Co. KG, D-73726 Esslingen, Germany, 2012)
Internet: http://www.festo.com
E-Mail: [email protected]
Reproduction, distribution or sale of this document or
communication of its contents to others without express
authorization is prohibited. Offenders will be liable for
damages. All rights reserved in the event that a patent, utility
model or design patent is registered.
Festo P.BE-MTR-DCI-IO-EN en 1209d
I
Page 4
Contents and general instructions
II
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 5
Contents and general instructions
Contents
Designated use VII........................................................
Safety instructions VIII.....................................................
Target group IX..........................................................
Service IX...............................................................
Scope of delivery IX.......................................................
Important user instructions X..............................................
Manuals on motor unit MTR-DCI XII..........................................
Information on the version XIII...............................................
Product-specific terms and abbreviations XIV...................................
1. System summary 1-1...............................................
1.1 Positioning with electric drives 1-3....................................
1.2 Components 1-6...................................................
1.3 Control and regulating functions 1-7...................................
1.4 Operational reliability 1-9............................................
1.5 Measuring reference system 1-10......................................
1.5.1 Basis points and work range 1-10..............................
1.5.2 Signs and directions 1-13.....................................
1.5.3 Homing 1- 14................................................
2. Mounting 2-1.....................................................
2.1 General instructions 2-3.............................................
2.2 Dimensions of the motor unit 2-4.....................................
2.3 Mounting electric axes 2-5...........................................
3. Installation 3-1...................................................
3.1 Overview of installation 3-3..........................................
3.2 Earthing 3-6.......................................................
3.3 Power supply 3-7..................................................
3.4 Serial interface 3-10.................................................
3.5 Input for external reference switch 3-12.................................
3.6 Connecting the higher-order controller 3-14..............................
Festo P.BE-MTR-DCI-IO-EN en 1209d
III
Page 6
Contents and general instructions
4. Control panel (MTR-DCI-...-H2IO) 4-1.................................
4.1 Composition and function of the control panel 4-4.......................
4.2 The menu system 4-6...............................................
4.2.1 Accessing the main menu 4-6.................................
4.2.2 Menu [Diagnostic] 4-8.......................................
4.2.3 Menu [Settings] 4-11.........................................
4.2.4 Menu [Positioning] 4-17.......................................
4.2.5 Menu command [HMI control] 4-20.............................
5. Commissioning 5-1................................................
5.1 Procedure for commissioning 5-3.....................................
5.2 Commissioning with the control panel (only MTR-DCI-...-H2) 5-6............
5.2.1 Selecting the axis type 5-7...................................
5.2.2 Setting the homing parameter 5-9.............................
5.2.3 Teach the axis zero point and the software end positions 5-13.......
5.2.4 Positioning with positio n sets 5-15..............................
5.2.5 Teach position sets 5-16......................................
5.2.6 Test run 5-17...............................................
5.3 Commissioning with FCT 5-19.........................................
5.3.1 Installing the FCT 5-19........................................
5.3.2 Procedure for commissioning with the Festo Configuration Tool 5-20..
5.4 Communication with the higher-order controller 5-22......................
5.4.1 I/O function check 5-22.......................................
5.4.2 Description of the I/Os 5-23...................................
5.4.3 Function description (pulse-time diagram) 5-26...................
6. Operating, maintenance and diagnosis 6-1............................
6.1 Important user instructions 6-3.......................................
6.2 Diagnosis and fault display 6-6.......................................
6.2.1 General diagnostic possibilities 6-6............................
6.2.2 LED status displays 6-7......................................
6.2.3 Fault messages on the display (only type MTR-DCI-...-H2) 6-9.......
IV
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 7
Contents and general instructions
A. Technical appendix A-1.............................................
A.1 Technical specifications A-3..........................................
A.2 Accessories A-6....................................................
A.3 Motor characteristic curves A-7.......................................
A.4 Converting measuring units A-13.......................................
B. Supplementary information B-1......................................
B.1 The Command Interpreter (CI) B-3.....................................
B.1.1 Procedure for data transfer B-4...............................
B.1.2 CI commands B-8...........................................
B.1.3 CI Objects (overview) B-12....................................
B.1.4 Object description B-16.......................................
C. Index C-1.........................................................
Festo P.BE-MTR-DCI-IO-EN en 1209d
V
Page 8
Contents and general instructions
VI
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 9
Contents and general instructions
Designated use
The MTR-DCI motor unit is an intelligent servo motor consisting of DC motor, planetary gear, encoder and integrated control electronics (positioning control and position regulator).
The mechanical layout and plug-in interface of the MTR-DCI
have been optimized for use with electric linear drives (e.g.
DMES) from Festo. The motor unit can also be used for customer-specific positioning applications with slow spindle
drives.
This manual deals with the basic functions of the MTR-DCI
and the I/O interface of the MTR-DCI-...I0. Additional components as well as the field bus variants of the MTR-DCI are described in separate manuals.
It is absolutely necessary to observe the “Safety instructions”
as well as the designated use of the relevant components and
modules. Observe also the safety instructions in the operating instructions for the electric components used.
The MTR-DCI and the connectable modules and cables may
only be used as follows:
– in accordance with designated use
– only in industrial applications
– without any modifications by the user. Only the conver-
sions or modifications described in the documentation
supplied with the product are permitted.
– in faultless technical condition.
If additional commercially-available components such as
sensors and actuators are connected, the specified limits for
temperatures, electrical data, torques, etc. must not be
exceeded.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Please observe the standards specified in the relevant
chapters and comply with technical regulations, as well as
with national and local regulations.
VII
Page 10
Contents and general instructions
Safety instructions
When commissioning and programming positioning systems,
you must observe the safety regulations in this manual as
well as those in the operating instructions for the other components used.
The user must make sure that nobody is in the operating
range of the connected actuators or axis system. Access to
thepossibledangerareamustbepreventedbysuitable
measures such as protective screens and warning signs.
Warning
Electric axes can move suddenly with high force and at
high speed. Collisions can lead to serious injury to human
beings and damage to components.
Make sure that nobody can gain access to the operating
range of the axes or other connected actuators and that no
objects lie in the positioning range while the system is still
connected to a power supply.
Warning
Faults in parametrization can cause injury to people and
damage to property.
Enable the controller only if the axis system is correctly
installed and parametrized.
VIII
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 11
Contents and general instructions
Target group
This manual is intended exclusively for technicians trained in
control and automation technology, who have experience in
installing, commissioning, programming and diagnosing
positioning systems.
Service
Please consult your local Festo repair service or write to the
following e-mail address if you have any technical problems:
Scopeofdelivery
The following items are supplied with motor unit MTR-DCI:
– Motor unit with integrated controller, optionally with
control panel
– Operating package on CD-ROM:
– User documentation (descriptions)
– Festo Configuration Tool with MTR-DCI plugin
– User documentation (quick reference guide)
Available as accessories (see appendix A.2):
– Connecting cable
Festo P.BE-MTR-DCI-IO-EN en 1209d
– Programming cable
– User documentation in paper form.
IX
Page 12
Contents and general instructions
Important user instructions
Danger categories
This manual contains instructions on the possible dangers
which may occur if the product is not used correctly. These
instructions are marked (Warning, Caution, etc.), printed on a
shaded background and marked additionally with a pictogram. A distinction is made between the following danger
warnings:
Warning
This means that failure to observe this instruction may
result in serious personal injury or damage to property.
Caution
This means that failure to observe this instruction may
result in personal injury or damage to property.
Note
This means that failure to observe this instruction may
result in damage to property.
The following pictogram marks passages in the text which
describe activities with electrostatically sensitive components.
X
Electrostatically sensitive components may be damaged if
they are not handled correctly.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 13
Contents and general instructions
Marking special information
The following pictograms mark passages in the text
containing special information.
Pictograms
Information:
Recommendations, tips and references to other sources of
information.
Accessories:
Information on necessary or sensible accessories for the
Festo product.
Environment:
Information on environment-friendly use of Festo products.
Text markings
•
The bullet indicates activities which may be carried out in
any order.
1. Figures denote activities which must be carried out in the
numerical order specified.
– Hyphens indicate general activities.
Festo P.BE-MTR-DCI-IO-EN en 1209d
XI
Page 14
Contents and general instructions
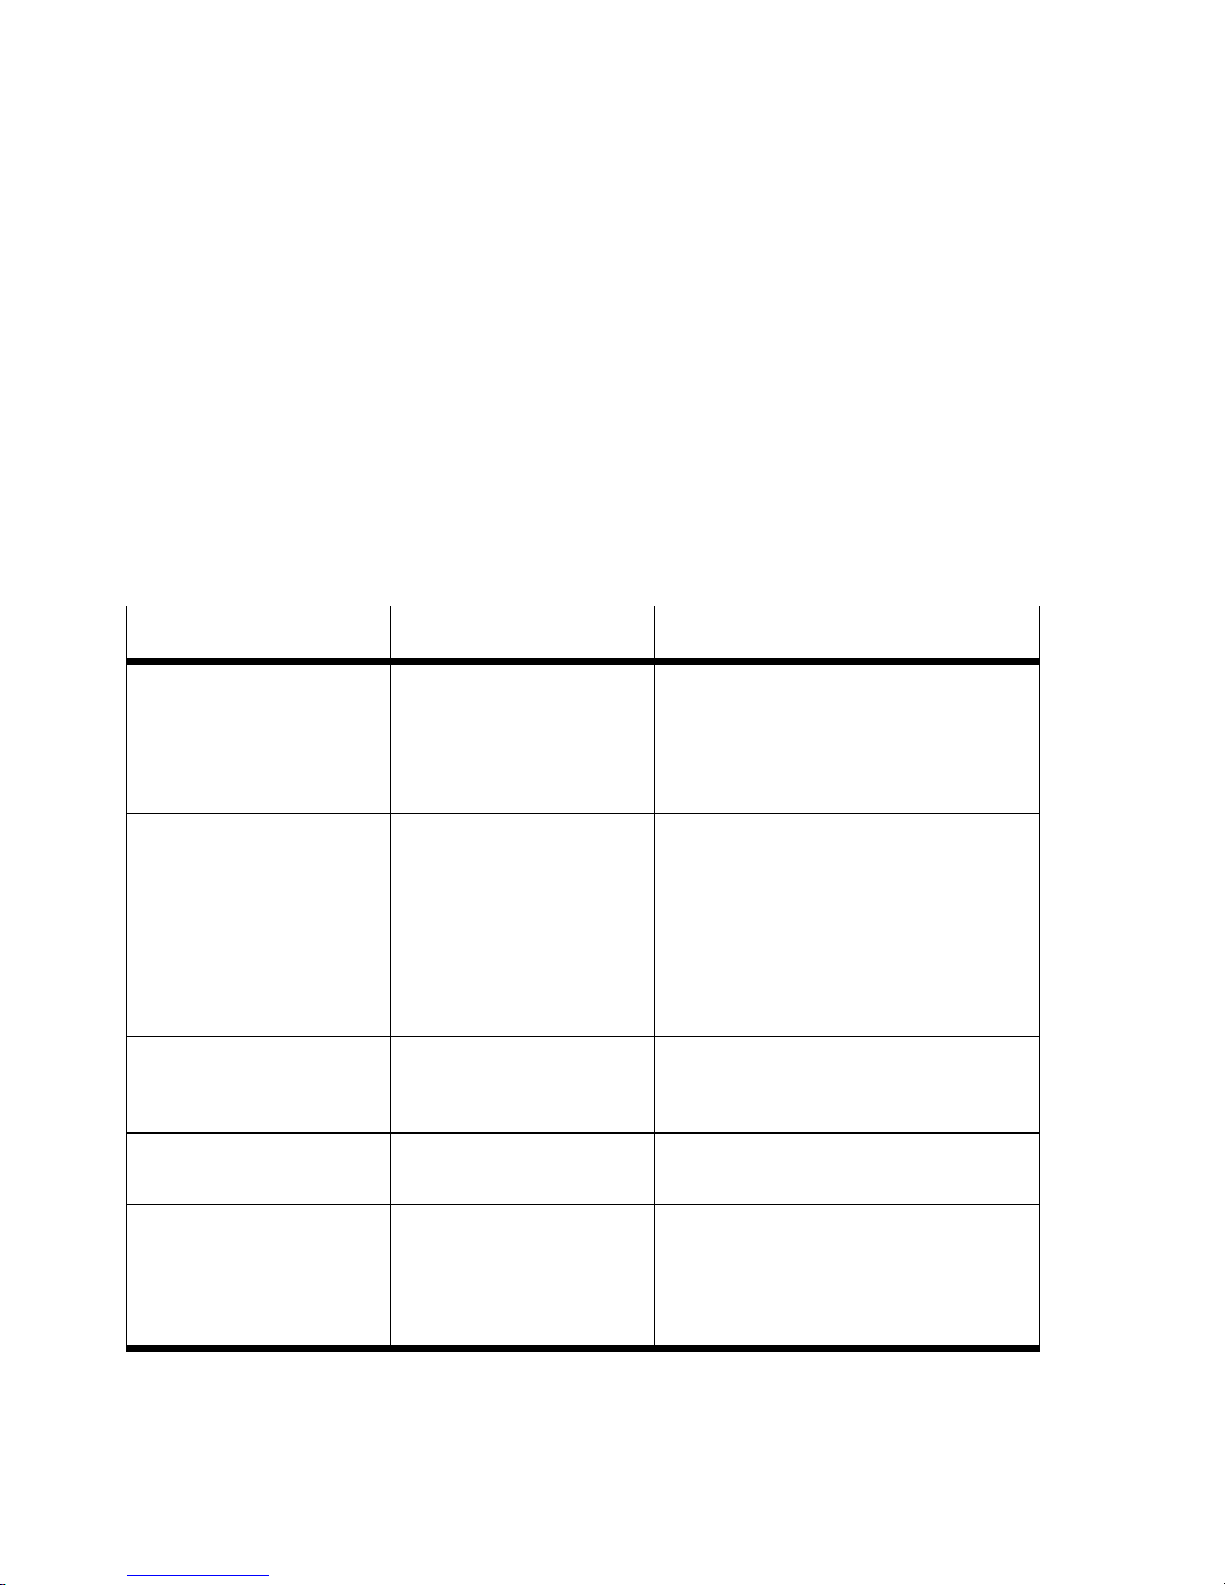
Manuals on motor unit MTR-DCI
This manual contains information on the method of operation, as well as on mounting, installing and commissioning
electric positioning drives with motor unit MTR-DCI-...IO (I/O
interface).
Information on components, e.g. the reference switch, can be
found in the operating instructions supplied with the product.
Type
Operating package with
brief description
+descriptions
(+ commissioning
software) on CD ROM
Description Motor unit MTR-DCI with
Help system for software Festo Configuration Tool
Operating instructions Positioning axis
Designation Contents
P.BE-MTR-DCI Brief description: Important instructions
I/O interface
P.BE-MTR-DCI-IO-DE
P.BE-MTR-DCI-IO-EN
P.BE-MTR-DCI-IO-FR
P.BE-MTR-DCI-IO-IT
P.BE-MTR-DCI-IO-ES
P.BE-MTR-DCI-IO-SV
help (contained in FCT
software)
DMES-...
on commissioning and preliminary
information.
Manuals on CD ROM: for motor unit
MTR-DCI (contents as described below)
Installation, commissioning and
diagnosis of electric axes with motor
unit MTR-DCI; communication via I/O
interface.
Function description of the Festo
Configuration Tool (FCT) configuration
software.
Mounting and commissioning the linear
axis with slide shaft as drive element.
Further manuals Motor unit MTR-DCI with
other communication interfaces e.g.
P.BE-MTR-DCI-CO
P.BE-MTR-DCI-PB
Tab. 0/1: Documentation on the MTR-DCI
XII
Installing, commissioning and diagnosing electric axes with motor unit MTRDCI; communication via the relevant
field bus.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 15
Contents and general instructions
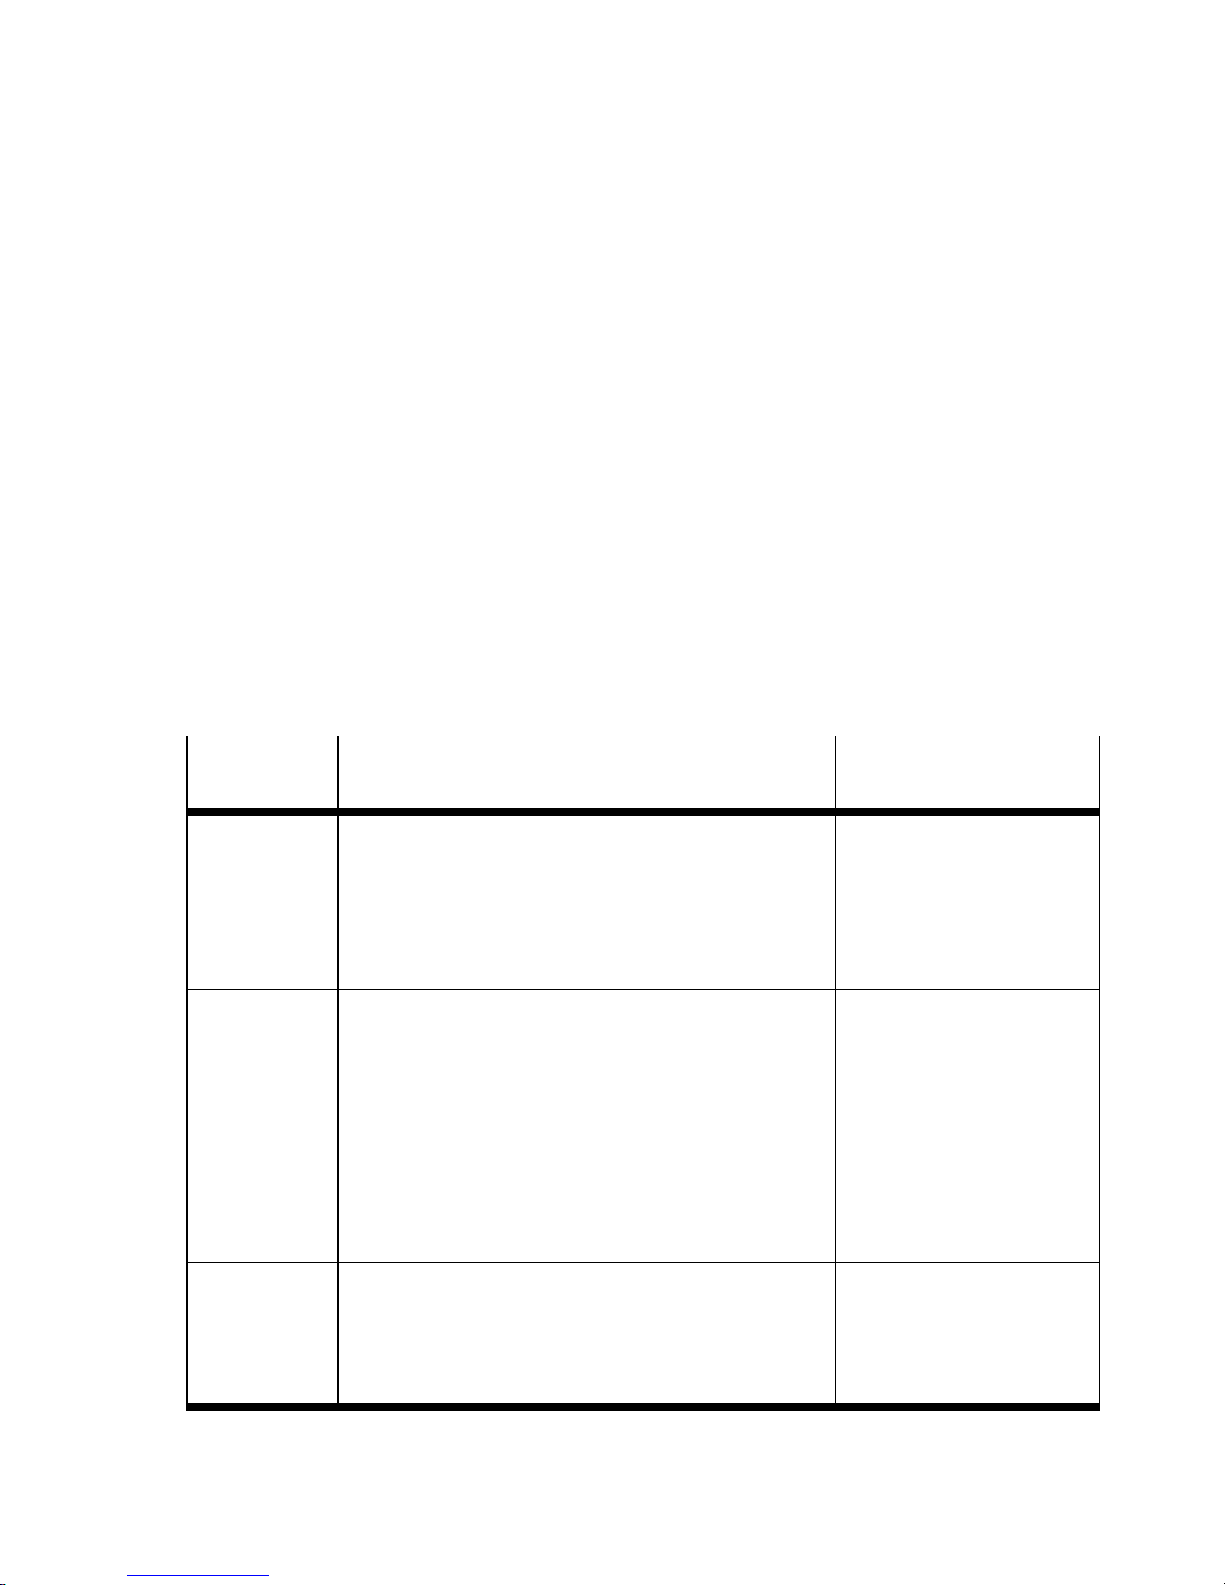
Informationontheversion
The hardware version specifies the version status of the
mechanical parts and electronics of the MTR-DCI. The firmware version specifies the version status of the o perating
system of the MTR-DCI.
You can find the specifications on the version status as
follows:
– Hardware version and firmware version in the Festo
Configuration Tool with active device connection to the
MTR-DCI under “Device data”
– Firmware version on the control panel under [Diagnostic]
[Software information]
Firmware
What is new? Which FCT PlugIn?
version
V-DME1.19 Supports the motor sizes MTR-DCI-42 and 52 and the
combination with the following positionin g axes from
Festo:
Motor unit Axis
MTR-DCI-42 DMES-25
MTR-DCI-52 DMES-40
V1.20 – Supports the motor sizes MTR-DCI-32 and 62 and
the combination with the following positioning
axes from Festo:
Motor unit Axis
MTR-DCI-32 DMES-18
MTR-DCI-42 DMES-25
MTR-DCI-52 DMES-40
MTR-DCI-62 DMES-63
MTR-DCI V1.0.0
MTR-DCI V1.1.0
– Modifying the start-up reaction of all sizes
V1.35 – Function “Save position when switching off” re-
moved.
The CI-parameter 60FB
the fixed value 240 (0x00F0) and cannot be overwritten, see appendix B.1.4.
Tab. 0/2: Firmware versions
Festo P.BE-MTR-DCI-IO-EN en 1209d
, s ubindex 20h,contains
h
MTR-DCI V2.1.1.4
XIII
Page 16
Contents and general instructions
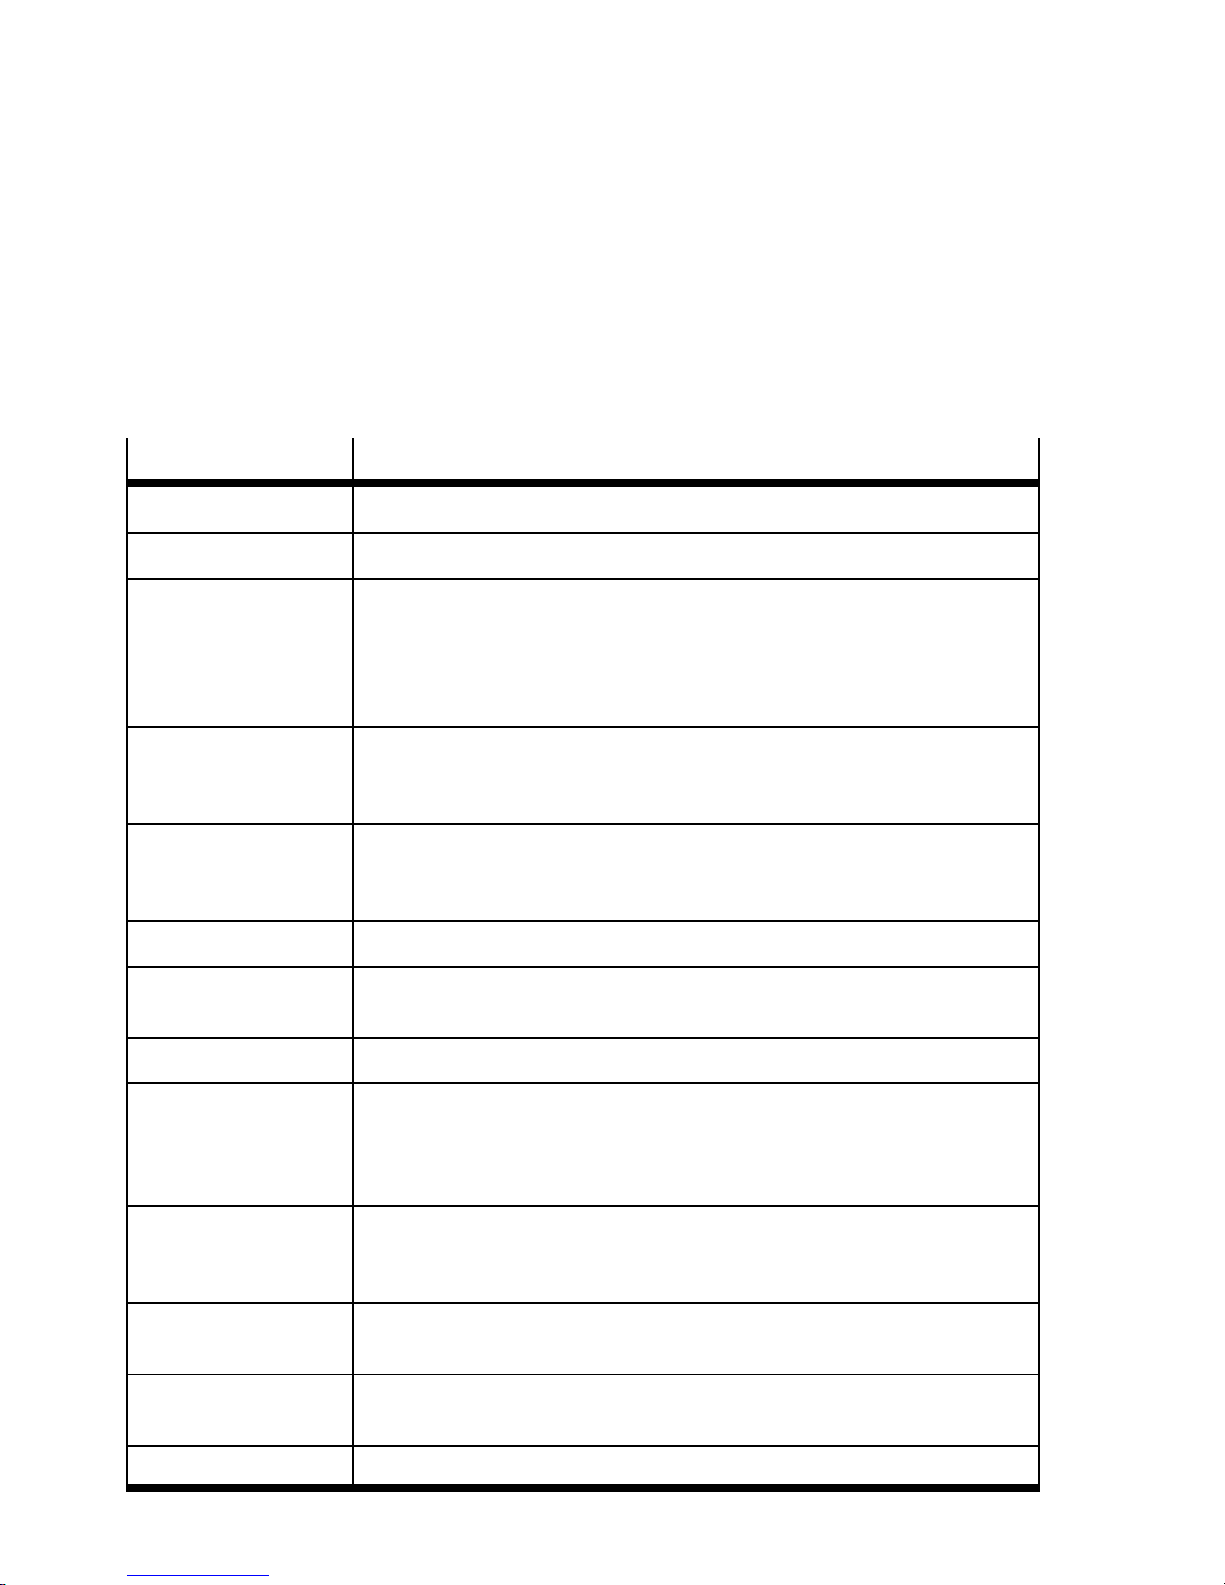
Product-specific terms and abbr eviations
The following product-specific terms and abbreviations are
used in this manual:
Term/abbreviation
0-signal 0 V present at input or output (positive logic, corresponds to LOW).
1-signal 24 V present at input or output (positive logic, corresponds to HIGH).
Axis Mechanical component of a drive which converts the motor revolutions into
Axis zero point (AZ) Measuring basis point for the project zero point and the software end
Controller Control electronics which evaluate the control signals and provide the
DMES Type designation, electric linear axis
Drive Complete actuator, c onsisting of c ontroller, motor, measuring system and,
Meaning
positioning movements of a work load. An axis (e.g. positioning axis
DMES-...) enables:
– the work load to be fitted and guided
– a reference switch to be fitted.
positions. The basis point for the axis zero point is the reference point.
Corresponds to the project zero point with the MTR-DCI (offset = 0).
power supply for the motor via the power electronics (power electronics +
controller + position controller).
if applicable, gear and (linear) axis.
EMC Electromagnetic compatibility
Encoder Optical pulse generator (rotor position transducer on the motor shaft of
the MTR-DCI). The electric signals generated are sent to the controller,
which then calculates the position and speed on the basis of the signals
received.
Festo Configuration
Tool (FCT)
HMI Human Machine Interface, with the MTR-DCI the control panel with
Homing meth od Method for determination of the reference position: against a fixed stop
Homing mode Operating mode in which a homing run is carried out.
Commissioning software with uniform project and data management for all
supported device types. The special requirements of a device type are
supported by PlugIns with the necessary descriptions and dialogues.
LC display and 4 operating buttons.
(overload current/speed evaluation) or with reference switch.
XIV
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 17
Contents and general instructions
Term/abbreviation Meaning
Homing run The reference position and therefore the source of the basis system of the
axis are defined by a homing run.
I
O
I/O
Jog mode Manual positioning in positive or negative direction (only on field bus
Motor unit Integrated unit consisting of the controller, motor, measuring system and,
Operating mode Type of controller or internal operating mode of the controller.
PLC Programmable logic controller; in brief: controller: (PLC: progammable
Positioning mode
(Profile position mode)
Position set Positioning command defined in the position set table, consisting of:
Input
Output
Input a nd/or output
variants of the MTR-DCI via the field bus or only with FCT or control panel).
if applicable, gears (e.g. motor unit MTR-DCI).
– Type of control: Record Select, Direct mode
– Operating mode of the controller: Position profile mode, homing mode,
Demo mode, ...
logic controller)
Operating mode for processing a position set or a direct positioning task.
– The number of the position set
– The absolute or relative basis of the nominal position
– The nominal position of the position set
– The positioning speed of the position set
Project zero point (PZ) Basis point for all positions in positioning tasks (Project zero point). The
Reference point (REF) Basis point for the incremental measuring system. The reference point
Reference switch External sensor (e.g. SMT-8 or SIEN) which serves for ascertaining the
Referencing Complete definition of the basis system of the axis with reference point
Festo P.BE-MTR-DCI-IO-EN en 1209d
project zero point forms the basis for all abso lut e position specifications
(e.g. in the position set table or with direct c ontrol via the control or diagnostic interface). The basis point for the project zero point is the axis zero
point. With the MTR-DCI the project zero point PZ and the axis zero point AZ
are identical.
defines a known orientation or position within the positioning path of the
drive.
reference position and is connected directly to the controller.
and, if applicable, zero point.
XV
Page 18
Contents and general instructions
Term/abbreviation Meaning
Software end position Programmable stroke limitation (basis point = axis zero point)
– Software end position, positive:
max. limit position of the stroke in the positive direction; must not be
exceeded during positioning.
– Software end position, negative:
min. limit position in the negative direction; must not be exceeded
during positioning.
Teach mode
(Teach mode)
Operating mode for setting positions by moving to the target position,
e.g. when creating position sets.
Tab. 0/3: Index of terms and abbreviations
XVI
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 19
System summary
Chapter 1
System summary
Festo P.BE-MTR-DCI-IO-EN en 1209d
1-1
Page 20
1. System summary
Contents
1. System summary 1-1...............................................
1.1 Positioning with electric drives 1-3....................................
1.2 Components 1-6...................................................
1.3 Control and regulating functions 1-7...................................
1.4 Operational reliability 1-9............................................
1.5 Measuring reference system 1-10......................................
1.5.1 Basis points and work range 1-10..............................
1.5.2 Signs and directions 1-13.....................................
1.5.3 Homing 1- 14................................................
1-2
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 21
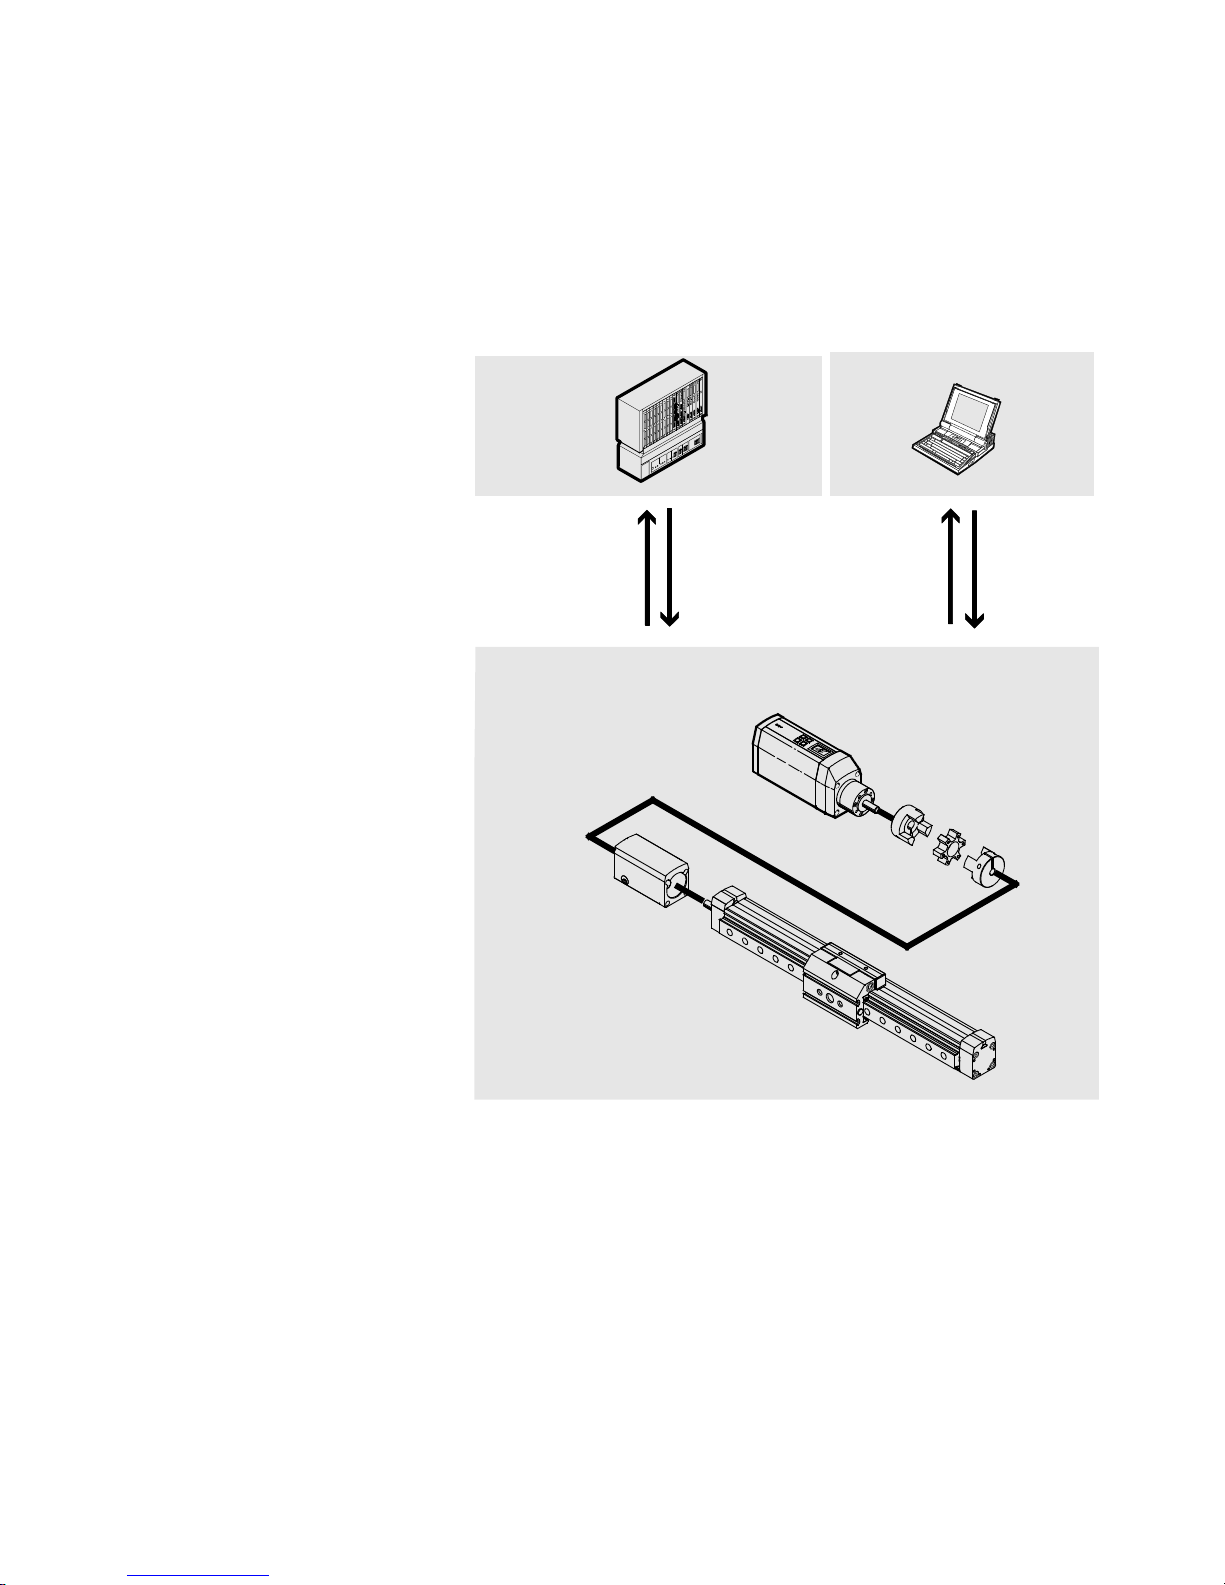
1. System summary
1.1 Positioning with electric drives
Process control
1
and parameter
access through
the higher-order
controller
12
2
Software level:
Commissioning
with the Festo
Configuration
Tool software
3
Drive level with
–Motorunit
– Coupling
– Coupling
housing
–Axis
I/O
CANopen
RS232
Profibus
DeviceNet
3
Fig. 1/1: Principle of a positioning system with motor unit MTR-DCI and positioning axis
DMES
Festo P.BE-MTR-DCI-IO-EN en 1209d
The motor unit MTR-DCI enables the connected linear or rotation axis to be placed in max. 15 positions (plus homing) with
separate speed adjustment.
The permitted positioning range can be limited by means of
software end positions.
1-3
Page 22
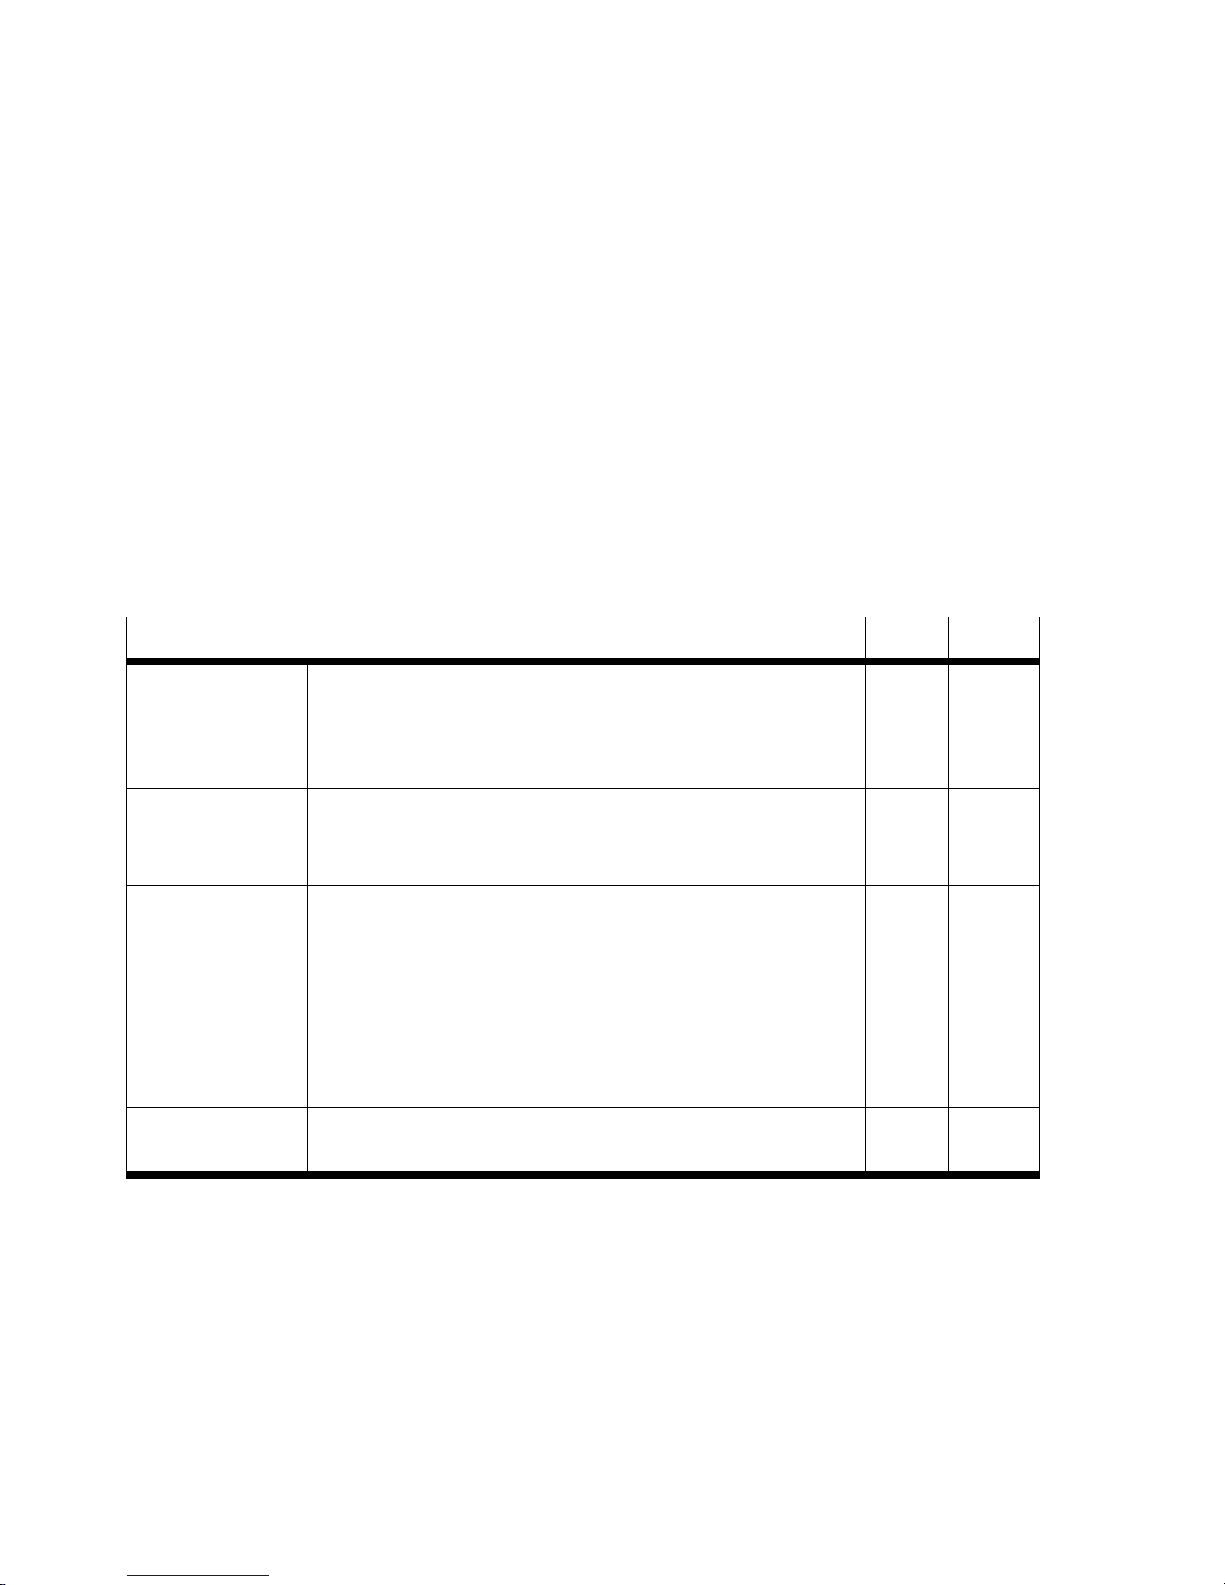
1. System summary
You can parametrize and commission the MTR-DCI as follows:
– with the FCT software package via the RS232 interface of
your PC
– with the optional control panel with display and 4 operat-
ing buttons (only MTR-DCI-...-H2)
Coupling to a higher-order PLC/IPC is carried out in operation
via digital inputs/outputs.
Functions
Parameterisation – Selecting the axis type and the axis parameters
– Specifying a gear factor (with external gears)
– Uploading/downloading of configuration data
– Saving different configurations in projects
Positioning
records
Commissioning –Homing
Diagnostics/
Service
– Compiling a position set table with set number, target
position, positioning mode, positioning speed,
acceleration
–Jogmode
– Teaching of positions
– Travel in individual steps
– Starting and stopping positioning procedures during
commissioning
– Extended test functions, e.g. status displays
– Testing or demonstrating the positioning records
– Reading and displaying diagnostic data x x
HMI FCT
x
–
–
–
x x
x
x
x
–
x
–
x
x
x
x
x
x
x
x
x
x
x
x
Tab. 1/1: Functions
1-4
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 23
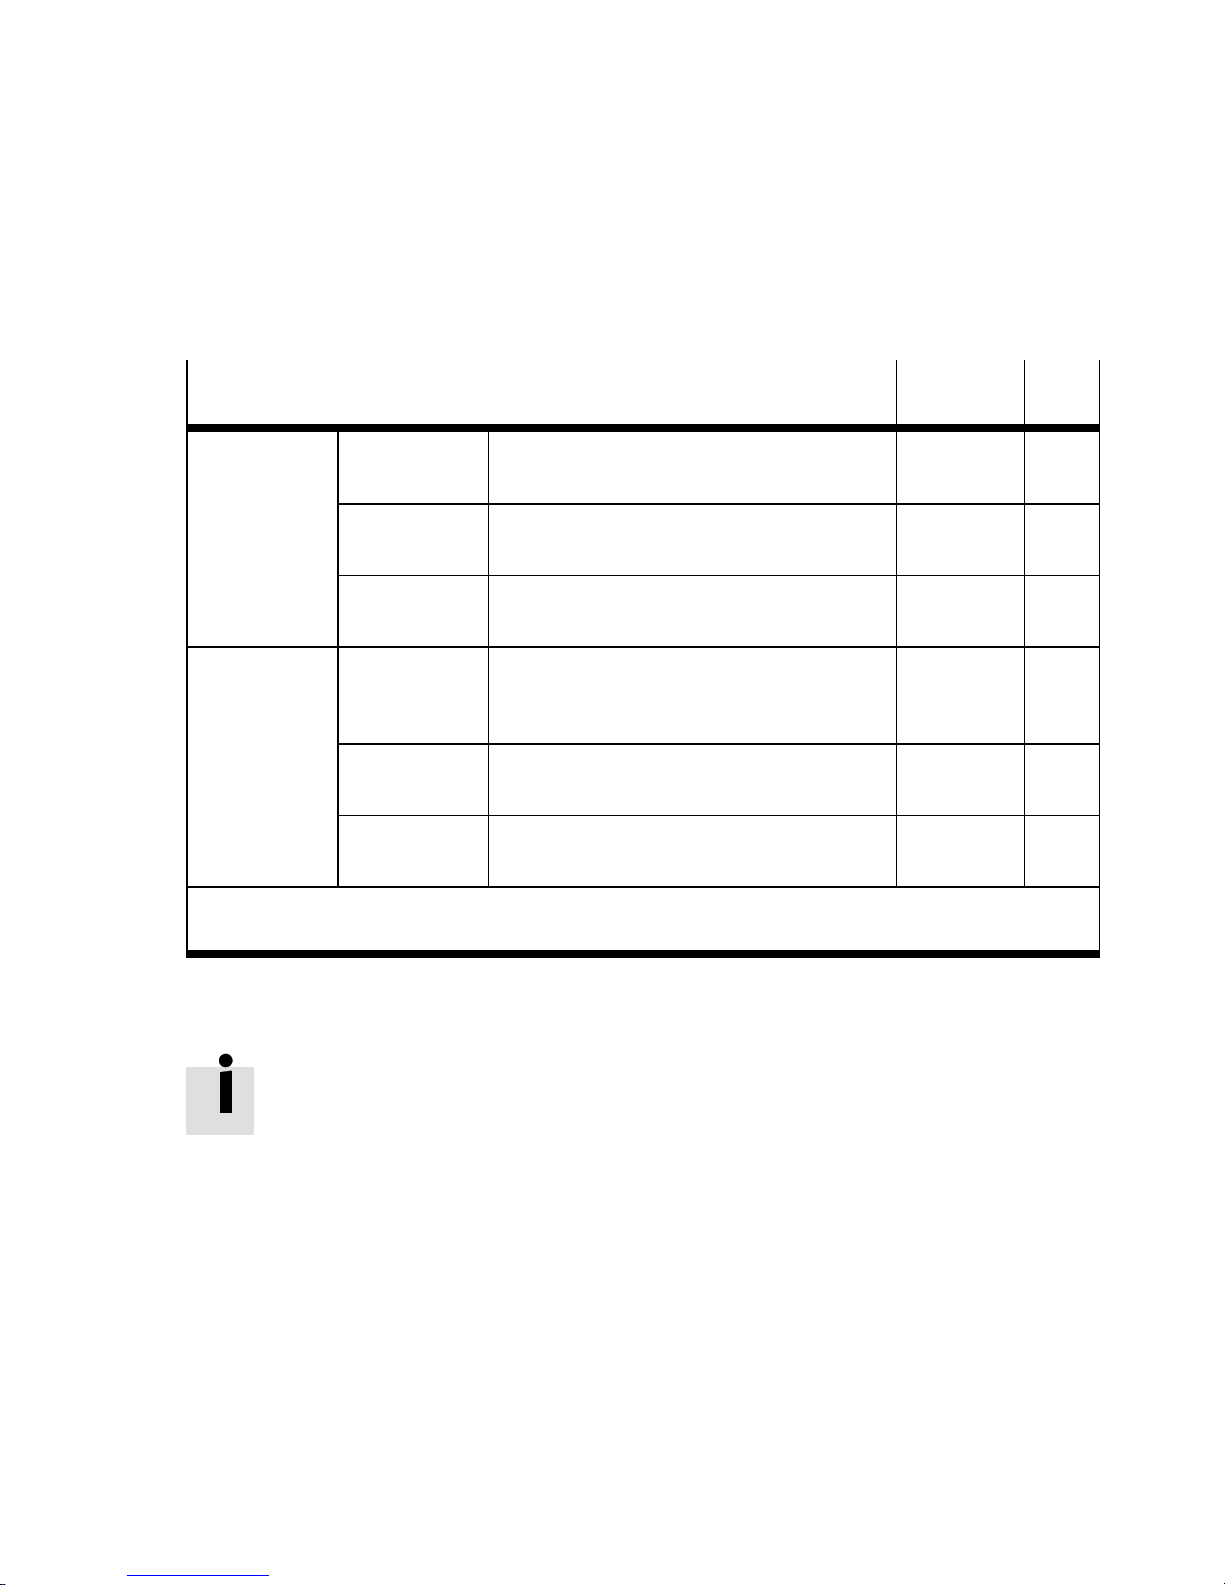
1. System summary
All parameters are entered or displayed in the relevant set
measuring units.
Units of Measurement
Linear axis
Rotation axis Degree Angle dimension
1)
Only with FCT when creating a project.
2)
Setting only with the control panel [Settings] [Axis type] [Rotation axis]
Metric Metric units of measurement,
2
2
Customs du-
1)
ties
e.g. mm, mm/s, mm/s
Imperial units of measurement,
e.g. inch, inch/s, inch/s
Increments Increment-based units of measurement,
e.g. inc, inc/s, inc/s
2
360° = 1 revolution
2
2
Revolutions
e.g. deg, deg/s, deg/s
2)
Number of revolutions
e.g. rev, rev/min, rev/min
Increments Increment-based units of measurement,
e.g. inc, inc/s, inc/s
2
Control
panel
x x
– x
– –
x x
x –
– –
FCT
Tab. 1/2: Units of Measurement
Festo P.BE-MTR-DCI-IO-EN en 1209d
Setting the units of measurement influences only the display. All the parameters in the controller are saved internally
in increments (inc, inc/s, inc/s
2
...) and are not converted until
they are written or read.
Measurements transmitted directly via RS232 are conducted
on an increment basis (for conversion see appendix A.4).
1-5
Page 24
1. System summary
1.2 Components
For setting up an electric drive with the MTR-DCI you will
require the following components:
Motor unit MTR-DCI Motor with controller, available in four sizes, optionally with
control panel (type ...-H2).
By means of different gear reductions, different requirements can be fulfilled in respect of (gear unit) output torque
and (gear unit) output speed (see appendix A.1). High drive
output torques with low drive output speeds are characteristic for positioning functions. With the smaller gear reduction, the positioning speed of the axis can be increased with
correspondingly reduced positioning force.
Axis Linear or rotation axes as per catalogue
Coupling with coupling
housing
For the axial attachment of Festo axes, e.g. type DMES-... or
type DNCE-..., couplings and coupling housings are available as accessories. The motor unit is connected to the axis
by means of a clamping connection in the coupling housing.
Additional motor flanges are not therefore necessary. Further information can be found in the operating instructions
for the axis.
Power supply cable for supplying the MTR-DCI with operating voltage via a
power unit (DC 24 V / size 62: 48 V)
Programming cable Parametrizing the MTR-DCI during commissioning with the
FCT
Homing Switch Sensor as per appendix A.2.
Accessories For positioning systems Festo offers special matching ac-
cessories (see Festo delivery program or catalogue).
1-6
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 25
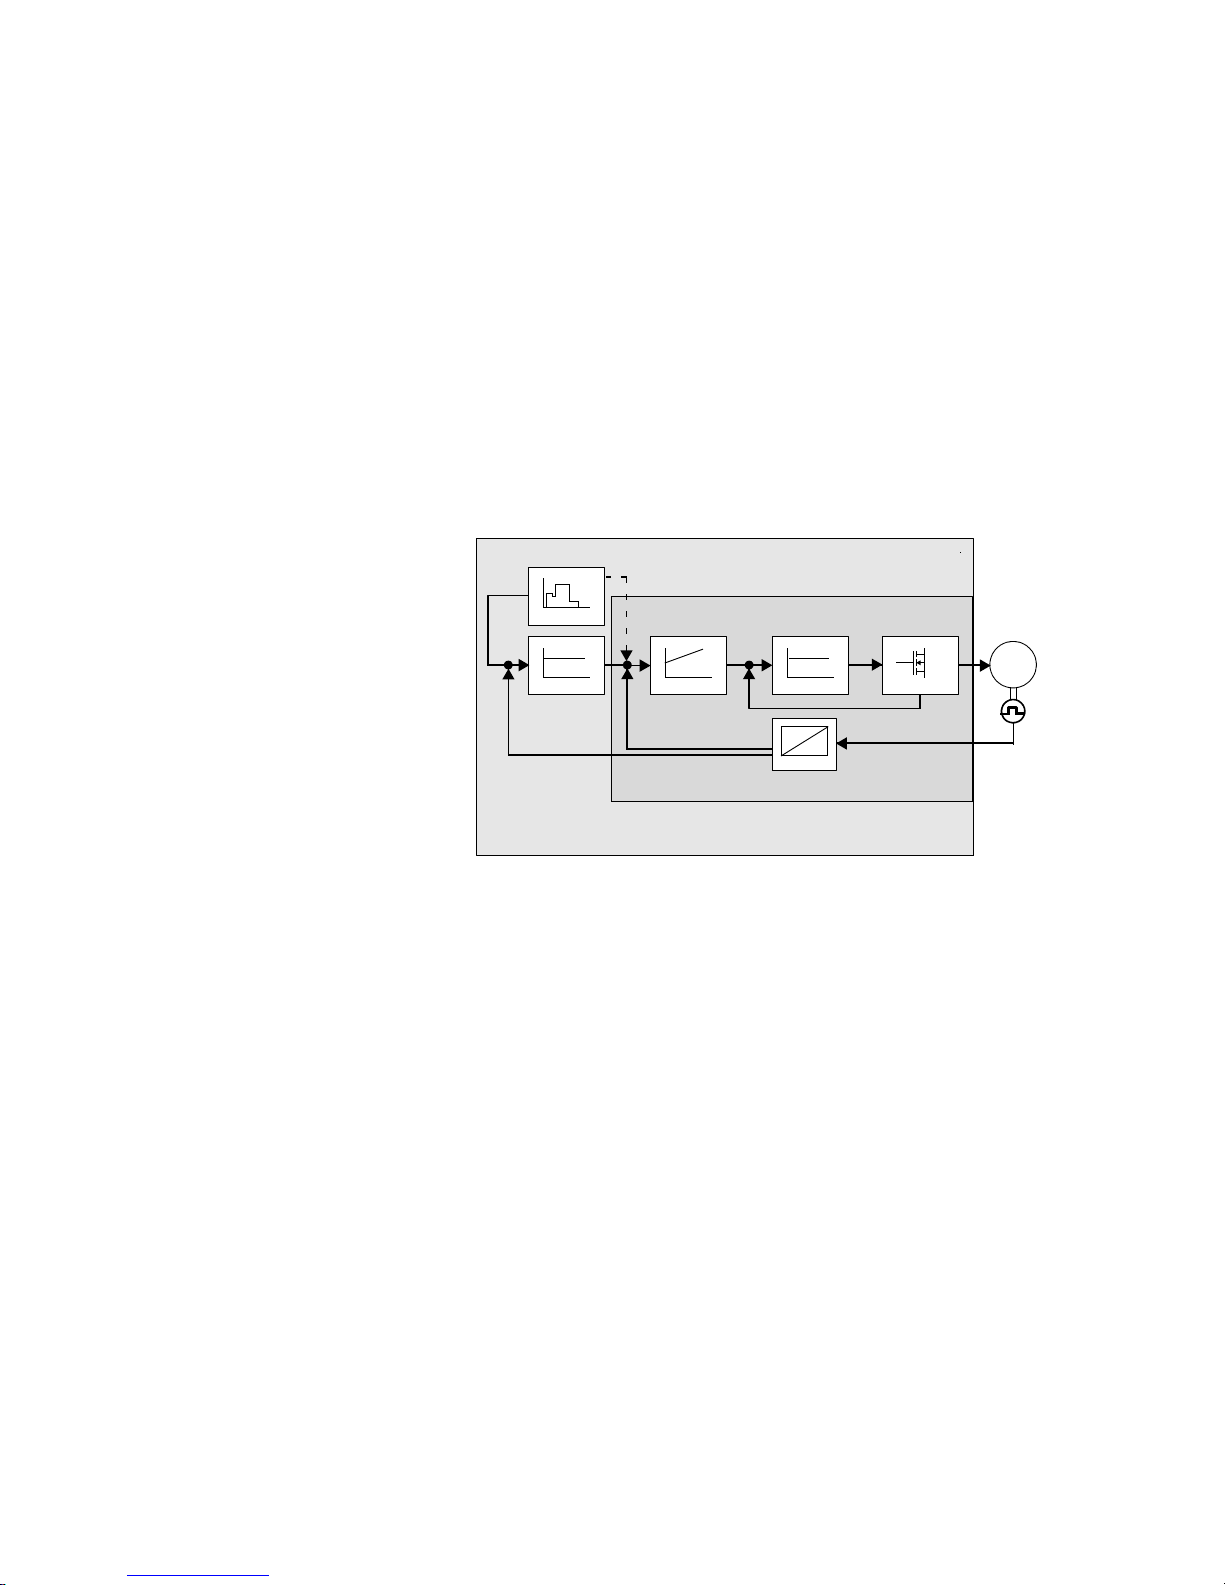
1. System summary
1.3 Controlandregulatingfunctions
The controller takes over the following tasks:
– specification of the nominal values
– regulation of the following factors: Position, speed, accel-
eration, current.
1
Motor controller
2
Regulator
3
Setpoint
value generator
4
Position controller
5
Velocity control
6
Current control
1
3
P
4
2
567
PI
P
8
M
7
Output stage
8
Signal converter
Fig. 1/2: Simplified diagram of the cascade regulator
Profile position mode Positioning mode
Operating mode for executing a position set or a direct positioning task with position control (closed loop position control).
The target position defines the position to which the drive
controller is to move. The target position is interpreted either
as an absolute or relative specification. The set target position is transferred to the setpoint value generator. This generates a setpoint position value for the position controller.
For position control the current settings for speed, acceleration, braking deceleration, etc. are taken into account.
Festo P.BE-MTR-DCI-IO-EN en 1209d
1-7
Page 26
1. System summary
Changes in position are recognized by the internal incremental sensor (optical encoder). With a known starting point the
actual position is calculated from the gear reduction and/or
the spindle slope.
Homing mode Homing.
Execution of a positioning procedure in which the reference
point and therefore the source of the measuring reference
system of the axis are defined, e.g. via a reference switch
within the possible positioning path or with overcurrent evaluation n the case of movement to a stop.
For commissioning, for testing or for demonstration the
following functions are also available via the control panel of
the MTR-DCI-...-H2:
– Positioning travel for defining the target position of a
positioning record [Settings][Position set].
– Positioning travel for testing all positioning records in the
positioning record table [Demo posit tab].
– Positioning travel for testing a certain positioning record
in the positioning record table [Move posit set].
1-8
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 27
1. System summary
1.4 Operational reliability
An extensive system of sensors and monitoring functions
ensure operational safety:
–i
– Temperature monitoring (measuring the motor tempera-
ture and the power end stage temperature)
– Current monitoring
– Voltage monitoring
2
t-monitoring
– Recognizing faults in the internal voltage supply.
– MTR-DCI-62...: detection of overvoltages in the inter-
mediate circuit; brake chopper integrated.
– Drag fault monitoring
– Software end position recognition.
Observe the following:
•
By the arrangement of the limit switches and, if necessary, additionally by means of mechanical stops, make
sure that the axis always lies within the permitted positioning range.
Festo P.BE-MTR-DCI-IO-EN en 1209d
1-9
Page 28
1. System summary
Warning
•
Please note that the MTR-DCI-…IO does not have a separate logic voltage supply.
•
Check the measures which are necessary within the
framework of your EMERGENCY STOP circuit for switching your machine/system into a safe state in the event
of an EMERGENCY STOP.
•
If corresponding EMERGENCY STOP circuitry is necessary for your application, use additional, separated
safety limit switches (e.g. as normally closed limit
switches wired in series connection)
– Cancelling the ENABLE signal at the controller inter-
face
– Switch off the load voltage.
1.5 Measuring reference system
For commissioning, a measuring reference system for referencing the reference coordinates must be defined. By means
of the measuring system all (absolute) positions are defined
and movement can be made to them.
1.5.1 Basis points and work range
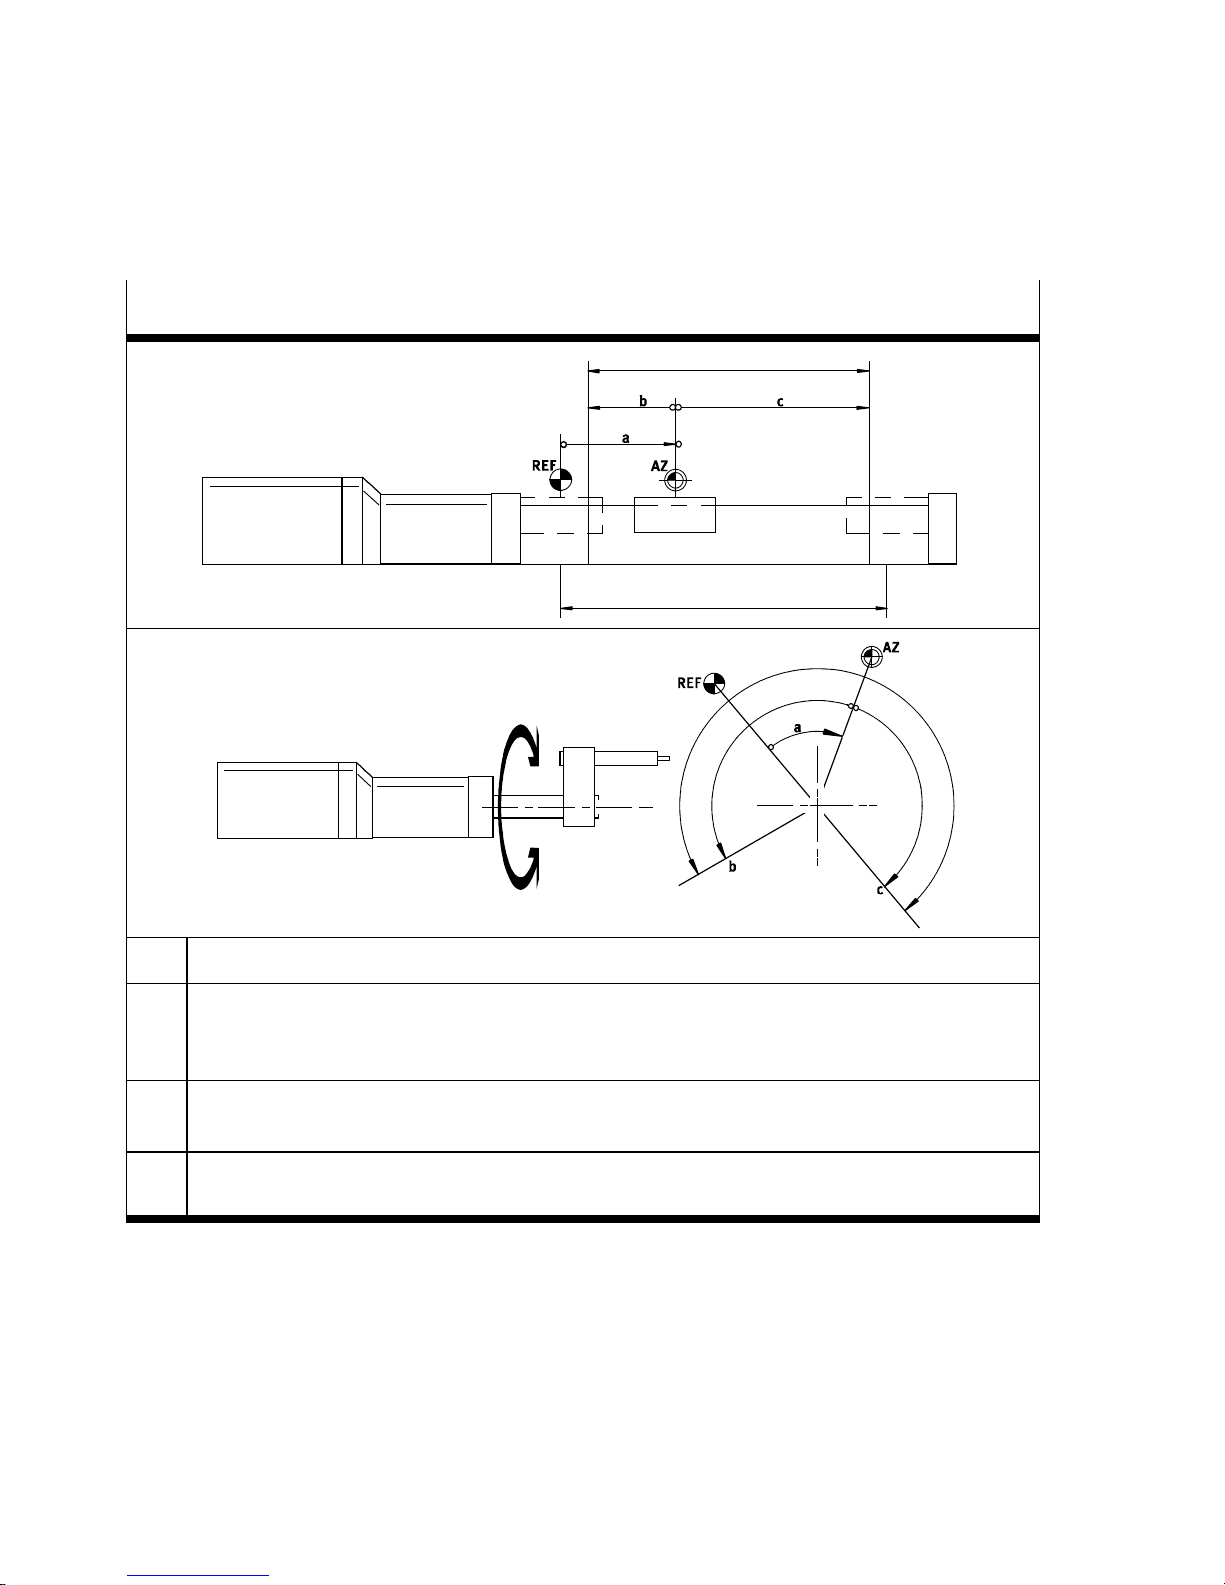
The basis system of the MTR-DCI is based on the axis zero
point which is defined by the offset to the reference point.
Homing run The position of the reference point REF is defined by a hom-
ing run. When a homing run is finished, the drive stands at
the axis zero point AZ.
Homing method The homing method defines the way in which the reference
Homing point REF forms the mechanical starting point of the measuring refer-
1-10
point is determined.
ence system and is defined for the homing run by a reference
switch or a fixed stop, depending on the homing method. It
is the reference point of the axis zero point.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 29
1. System summary
Axis zero point AZ is shifted by a defined distance from the reference point REF
(axis zero point offset) and is the basis point of the software
end positions and the project zero point PZ. By defining the
axis zero point AZ and the software end positions you can
limit the work area of the linear axis to the permitted range
(work stroke).
Software end positions limit the permitted positioning range (work stroke). If the
target position of a positioning command lies outside the
software end positions, the positioning command will not be
processed and a fault status will be displayed.
Project zero point PZ is a basis point which the user can freely select within the
workstrokeandtowhichtheactualpositionaswellasthe
target positions in the position set table refer. The axis zero
point AZ is the basis point for the project zero point.
The project zero point PZ is specified with the MTR-DCI and is
identical to the axis zero point AZ (project zero point offset =
0).
Festo P.BE-MTR-DCI-IO-EN en 1209d
1-11
Page 30
1. System summary
Measuring reference system: basis points and work range
Linear axis with homing method:
Fixed stop negative
Rotation axis with homing method:
Reference switch negative
d
e
REF Reference point: Point determined during homing run: reference switch or stop
AZ Axis zero point: reference point for the project zero point and the software end positions.
Corresponds to the project zero point with the MTR-DCI (offset project zero point = 0).
The basis point for the axis zero point is the reference point.
A
b, c
d
e
Offset axis zero point: Defined distance of the axis zero point AZ from the reference point REF
Software end positions: limit the permitted positioning range (work stroke).
Work stroke: Permitted positioning range.
Rated stroke of the axis used
Tab. 1/3: Measuring reference system
1-12
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 31
1. System summary
1.5.2 Signs and directions
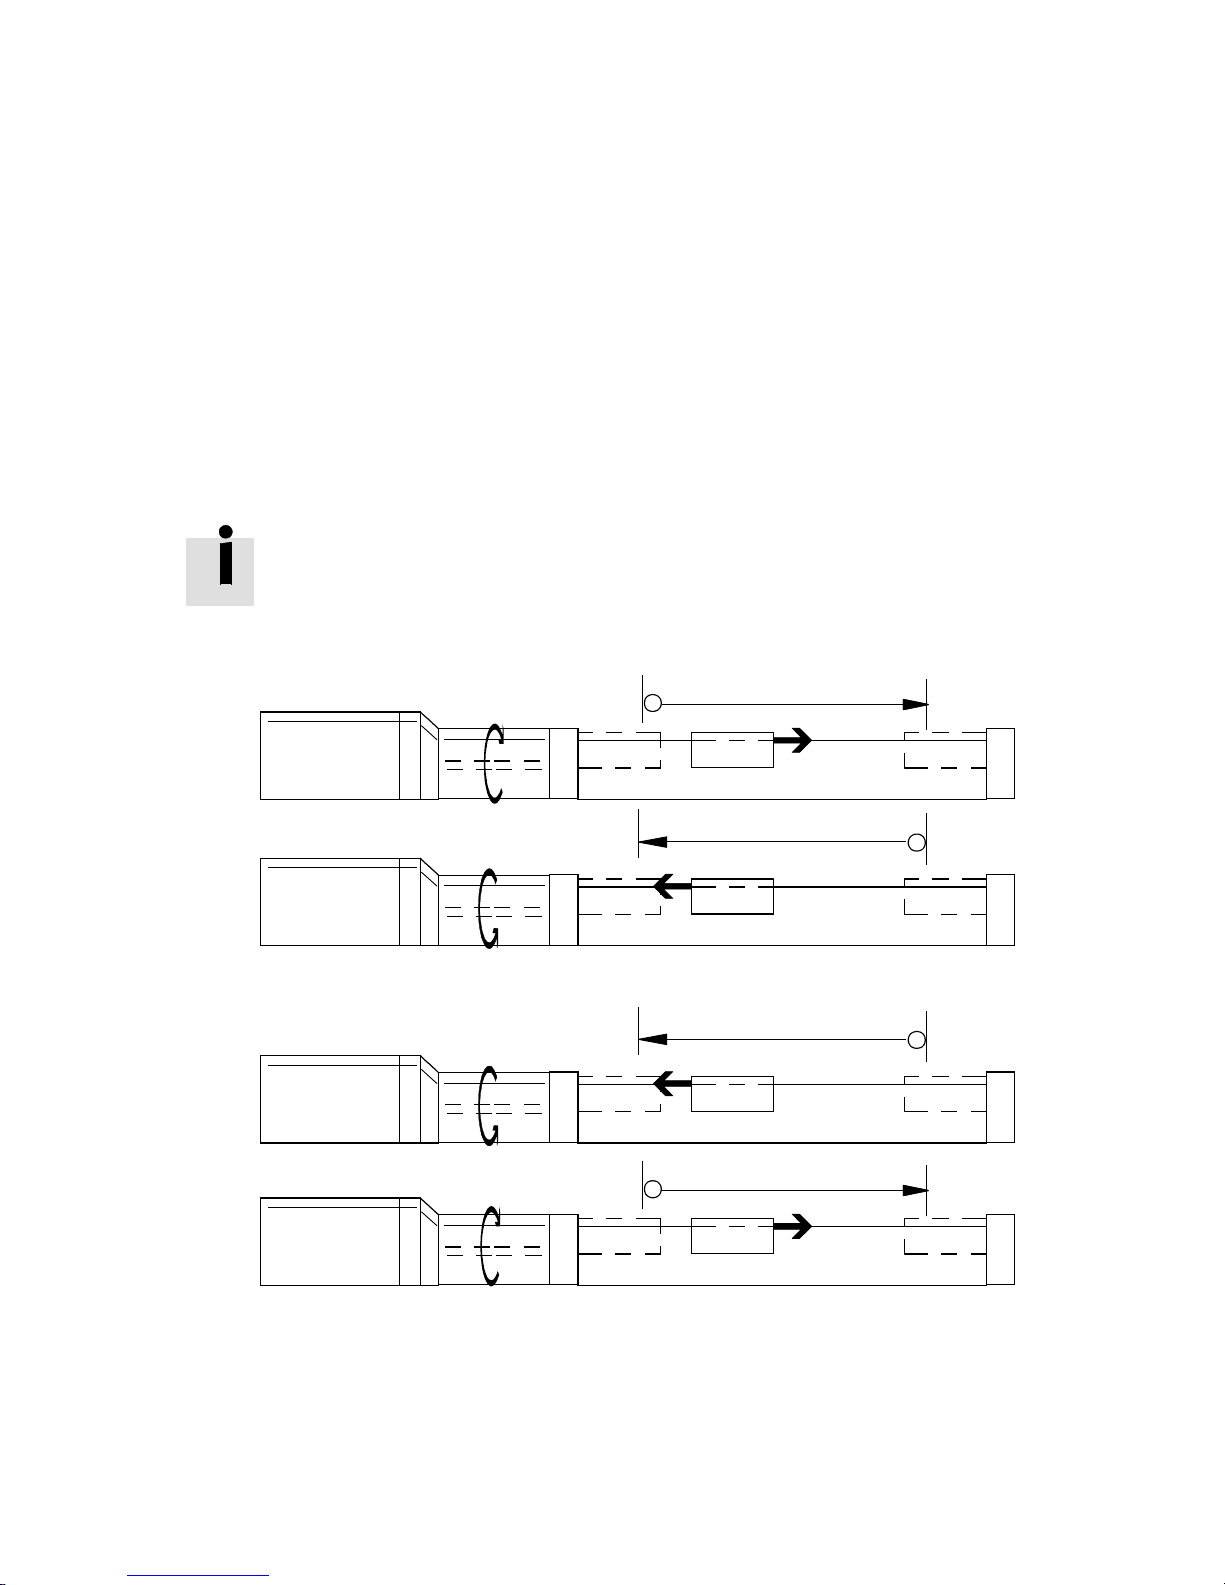
All offsets and position values are vectors (with a given algebraic sign, + or -). The active direction can be reversed on
the control panel (see 5.2.1) or via FCT. This can be useful
when using angular gear units or toothed belt drives. A homing run must be ca rried out again if the direction is reversed.
The direction in which the work load moves depends on the
gearing, the spindle type (left/right-rotating), the algebraic
signs on the positioning specifications, and the set active
direction.
1
2
+
—
+
—
Factory setting for active direction
1
2
Reversal of direction
Fig. 1/3: Active direction (using the exa mple of MTR-DCI + DMES, axial gearing)
Festo P.BE-MTR-DCI-IO-EN en 1209d
1-13
Page 32
1. System summary
1.5.3 Homing
In the case of drives with incremental measuring system,
homing must always be carried out after the drive is switched
on.
The following homing modes are permitted:
– Search for stop in a negative direction
– Search for stop in a positive direction
– Search for reference switch in a positive direction
– Search for reference switch in a negative direction
(default).
In order to search for the reference point and for positioning
the drive in the axis zero point, you can set two different
speeds.
Homing sequence:
1. Search for the reference point in accordance with the
configured method.
2. Move from reference point to axis zero point AZ (offset
axis zero point)
After successful homing the drive stands at the axis zero
point AZ. On initial commissioning or following a change of
homing method the axis zero offset is = 0; after homing the
drive is then positioned at the reference point (REF).
1-14
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 33
1. System summary
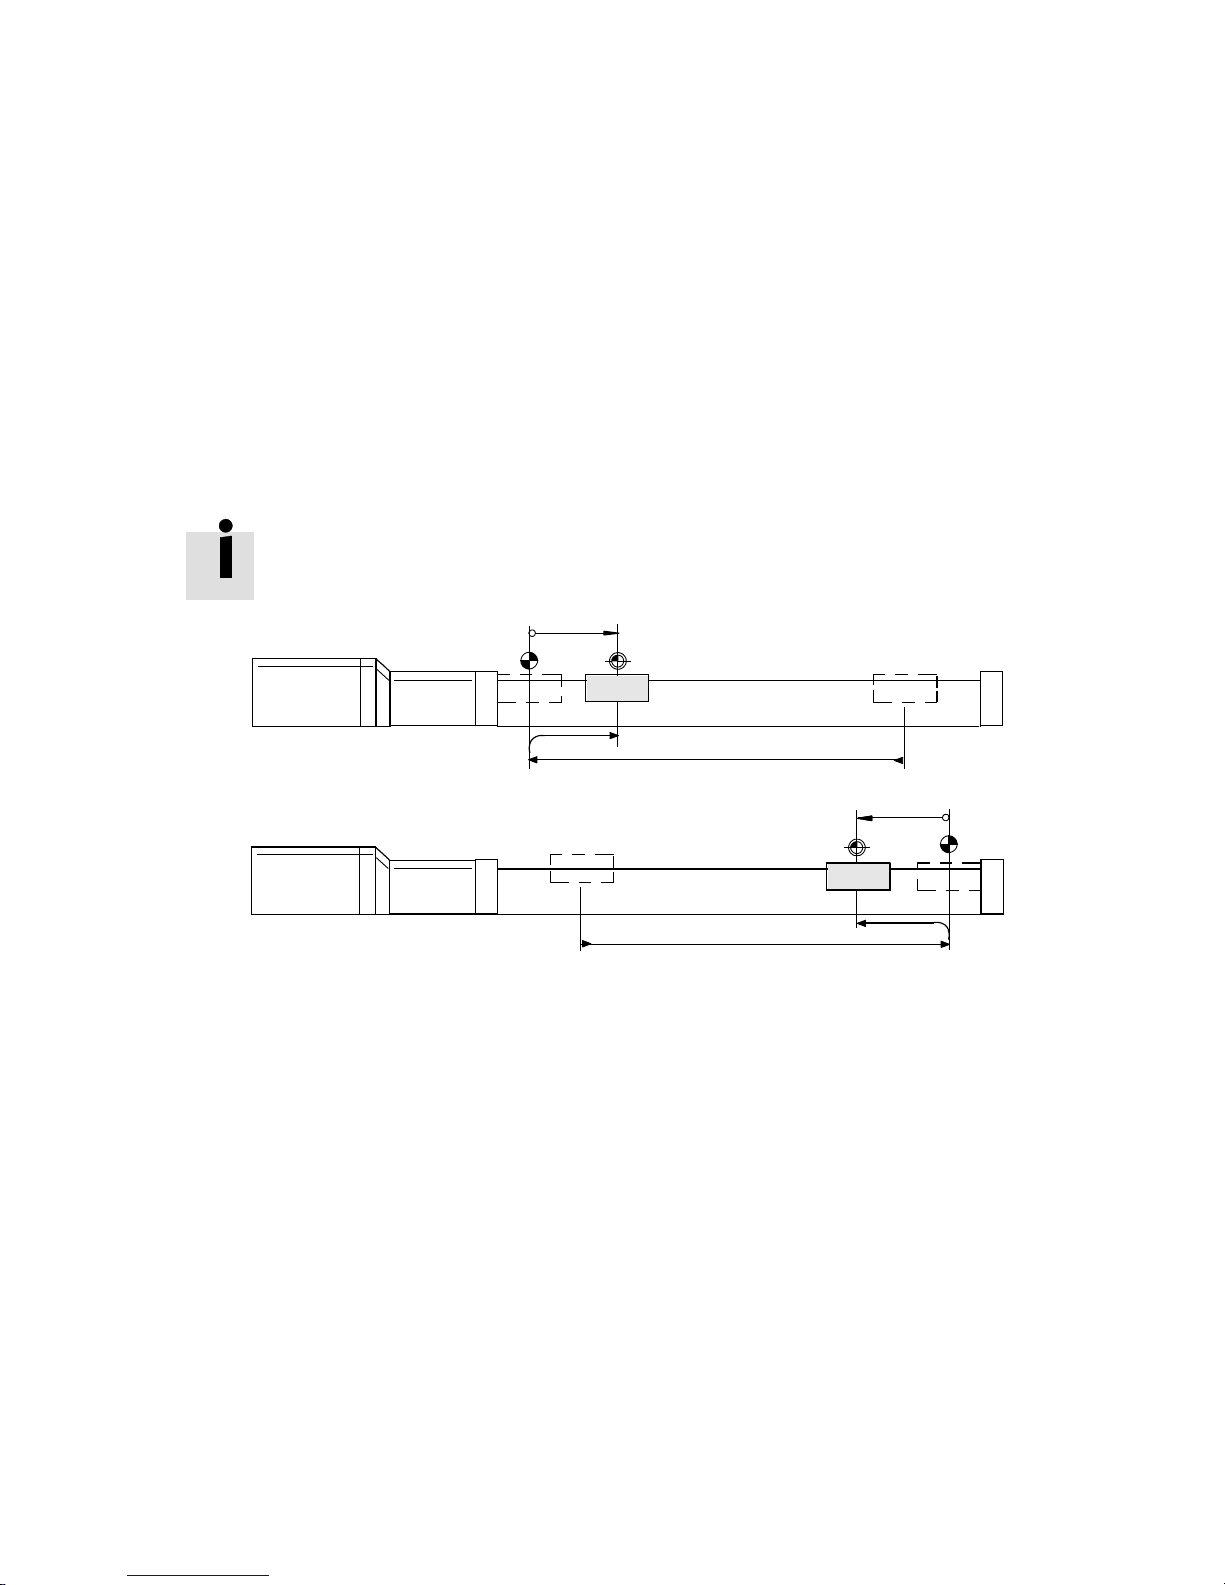
Search for fixed stop With this reference travel method, at first the drive moves at
search speed in a negative or positive direction until it
reaches the fixed stop. A rise in the motor current signals that
the stop has been reached. When the maximum motor current is reached at the same time as the motor is at a standstill, the MTR-DCI recognizes that the stop, and therefore the
reference position, has been reached.
As the axis should not stand still at the stop, the axis z ero
point offset must be ≠ 0 (min. 0.25 mm).
+
1
AZ
REF (-)
2
1
Stop in a negative direction
2
Stop in a positive direction
Fig. 1/4: “Search for fixed stop” reference travel method
—
AZ
REF (+)
Festo P.BE-MTR-DCI-IO-EN en 1209d
1-15
Page 34
1. System summary
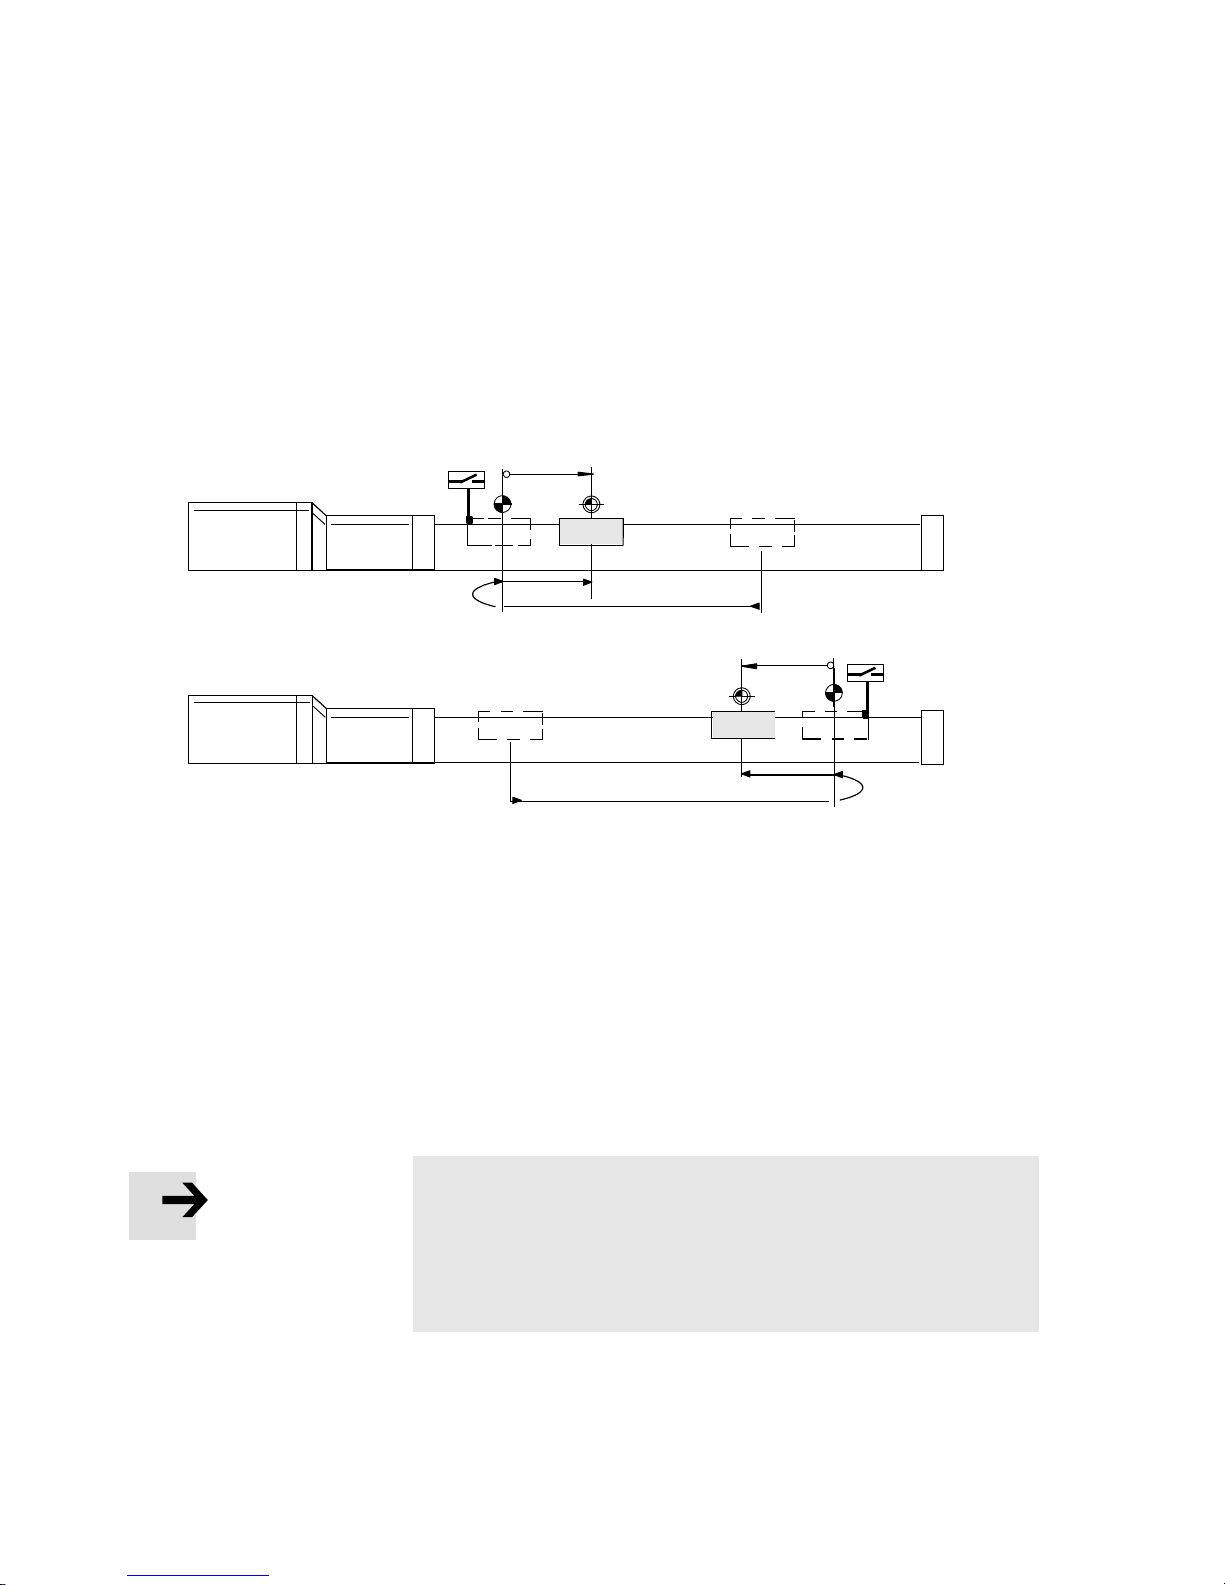
Search for reference switch With this reference travel method, at first the drive moves at
search speed in a negative or positive direction until it
reaches the limit switch. It then moves back at creep speed:
The reference position lies at the point at which the reference
switch becomes inactive again when the drive moves back.
+
1
REF (-)
AZ
2
AZ
1
Reference switch in negative direction
2
Reference switch in positive direction
Fig. 1/5: “Search for reference switch” reference travel method
If the drive stands on the reference switch at the start of reference travel, it will move in the opposite direction to the
reference switch. The drive then moves as usual to the axis
zero point.
—
REF (+)
1-16
Note
If a reference signal is not found by the “reference switch”
homing method before the drive reaches a fixed stop, the
MTR-DCI will stop and an error will be displayed (HOMING
ERROR).
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 35
Mounting
Chapter 2
Mounting
Festo P.BE-MTR-DCI-IO-EN en 1209d
2-1
Page 36
2. Mounting
Contents
2. Mounting 2-1.....................................................
2.1 General instructions 2-3.............................................
2.2 Dimensions of the motor unit 2-4.....................................
2.3 Mounting electric axes 2-5...........................................
2-2
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 37
2. Mounting
2.1 General instructions
Warning
Electric shock
Before carrying out mounting, installation and mainten-
ance work, always switch off the power supply for the electronic components.
Note
Handle all modules and components with great care.
Please note especially the following:
– Screw connections must be fitted free of offset and
mechanical tension. Screws must be fitted accurately
(otherwise threads will be damaged).
– The specified torques must be observed.
– The modules must not be offset.
– Contact surfaces must be clean (avoid contact faults).
Festo P.BE-MTR-DCI-IO-EN en 1209d
2-3
Page 38
2. Mounting
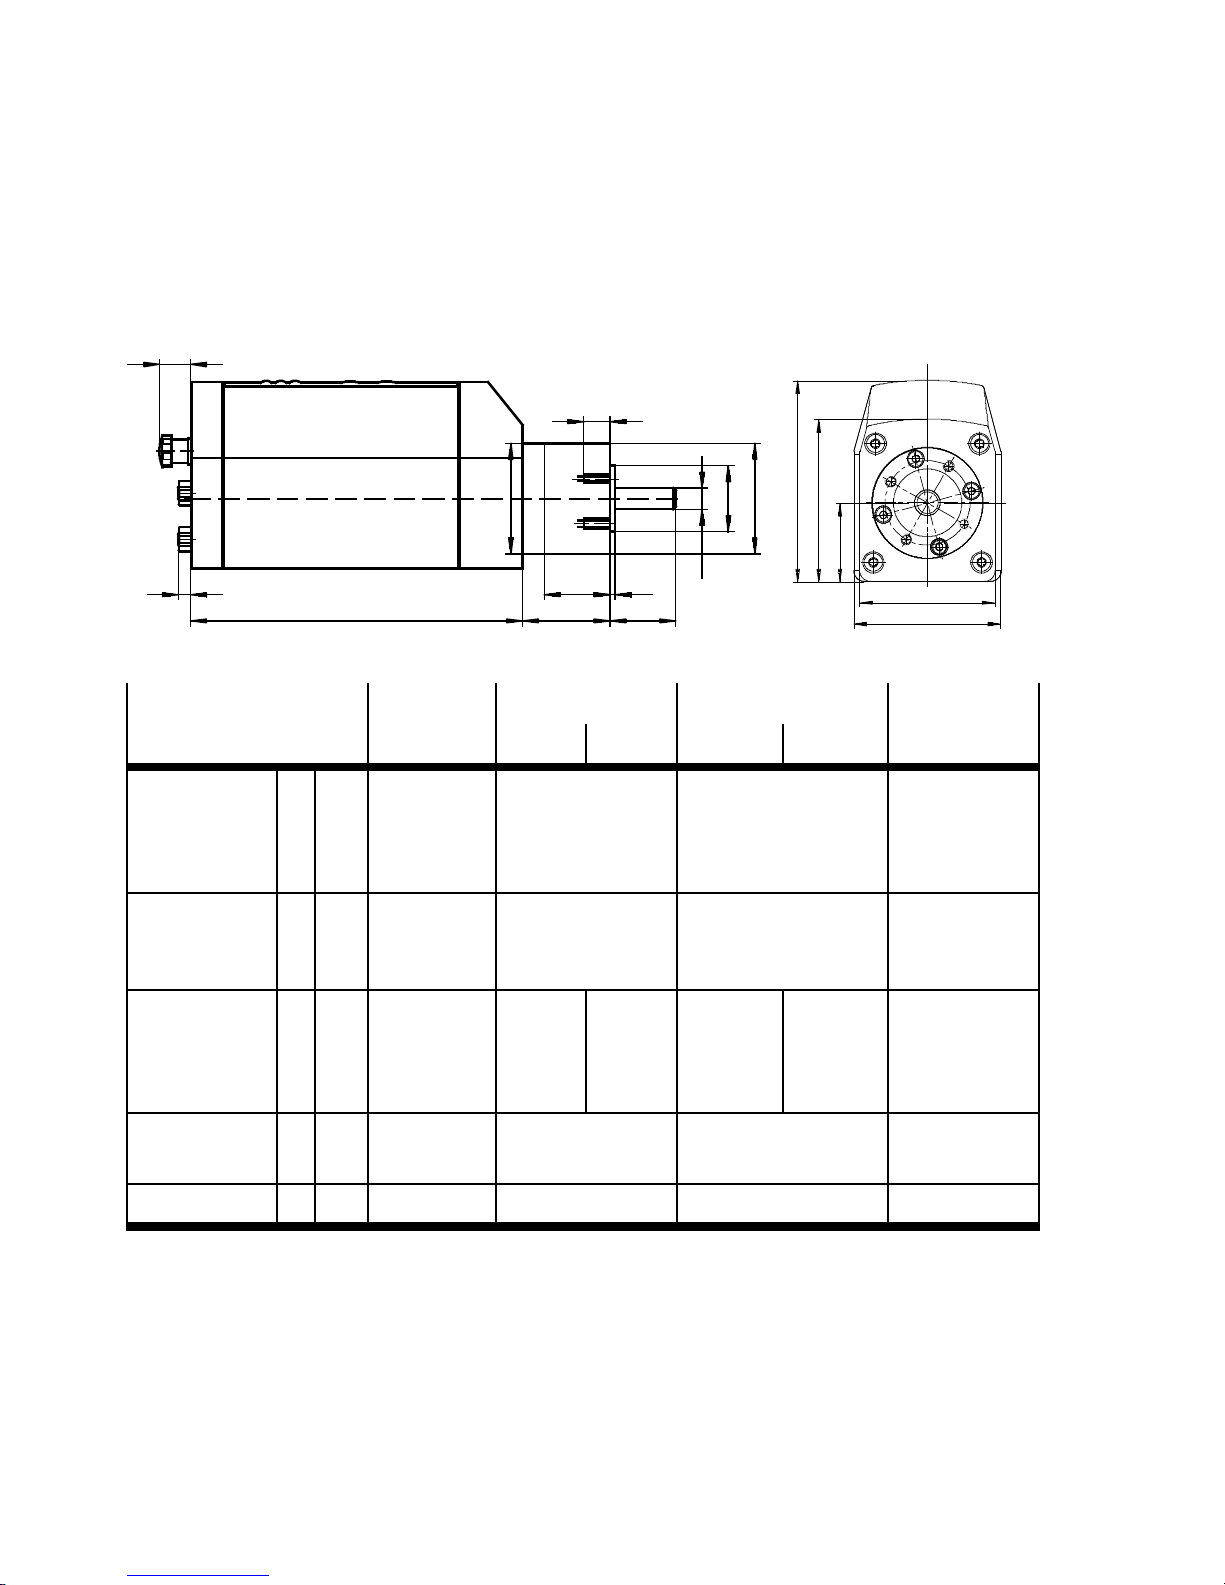
2.2 Dimensions of the motor unit
13
T1
D2
5
L1
L5
L2
L4
L3
D3
D4
D1
H0
H2
H1
B1
B2
Sizes [mm] 32 42 52 62
Gear ratio G7/G14 G7 G14 G7 G14 G7/G14/G22
Diameter of
flange/shaft
Height H H0
Length L L1
D D1
D2
D3
D4
H1
H2
L2
L3
L4
—
—
21.5 h8
6h7
65.3 ±0.4
21.6 ±0.15
41.5 ±0.3
175.5 ±1
—
18.7 ±0.6
2.5 ±0.3
42 g10
42 ±0.1
25 h8
8h7
70,8 ±0,4
26,5 ±0,6
54,5 ±0,4
176 ±1
33.3 ±1
25 ±1
2±0.2
176 ±1
46,3 ±1
25 ±1
2±0.2
52 g10
52 ±0.1
32 h8
12 h7
94.8 ±0.4
37 ±0,9
76.5 ±0.4
194 ±1
39 ±1
33 ±1
3±0.3
194 ±1
53 ±1
33 ±1
3±0,3
62 g10
62 ±0.1
40 j7
14 h7
128 ±0.5
60.8 ±0.35
128 ±0.5
270 ±1
47 ±1
39 ±1
5±0.3
Width B B1B233.8 ±0.3
46.3 ±0.4
Depth T T1 6 M3: 7 / M4: 10 10 10
Tab. 2/1: Dimensions of the motor unit
2-4
44.8 ±0.4
53.3 ±0.4
63.8 ±0.4
69.5 ±0.4
105.1 ±0.4
105.1 ±0.4
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 39
2. Mounting
2.3 Mounting electric axes
Refer to the following documentation when mounting the
electric axis:
– Operating instructions for the axis used.
– Instructions for the components used.
Warning
If an axis is fitted in a sloping or vertical position, the work
load may fall down and injure somebody.
•
Use the motor unit preferably with self-locking or self-
braking spindle drives. You can then avoid the working
mass sliding down if there is a sudden power failure.
•
With DMES: Check whether additional external safety
measures against spindle nut fracture are necessary
(e.g. toothed latches or moving bolts).
Make sure that:
•
the drive is fitted securely and is free of distortion,
•
the work space, in which the axis moves, is of sufficient
size for operation with a work load,
•
the work load does not collide with any component of the
drive when the slide moves into the end position.
•
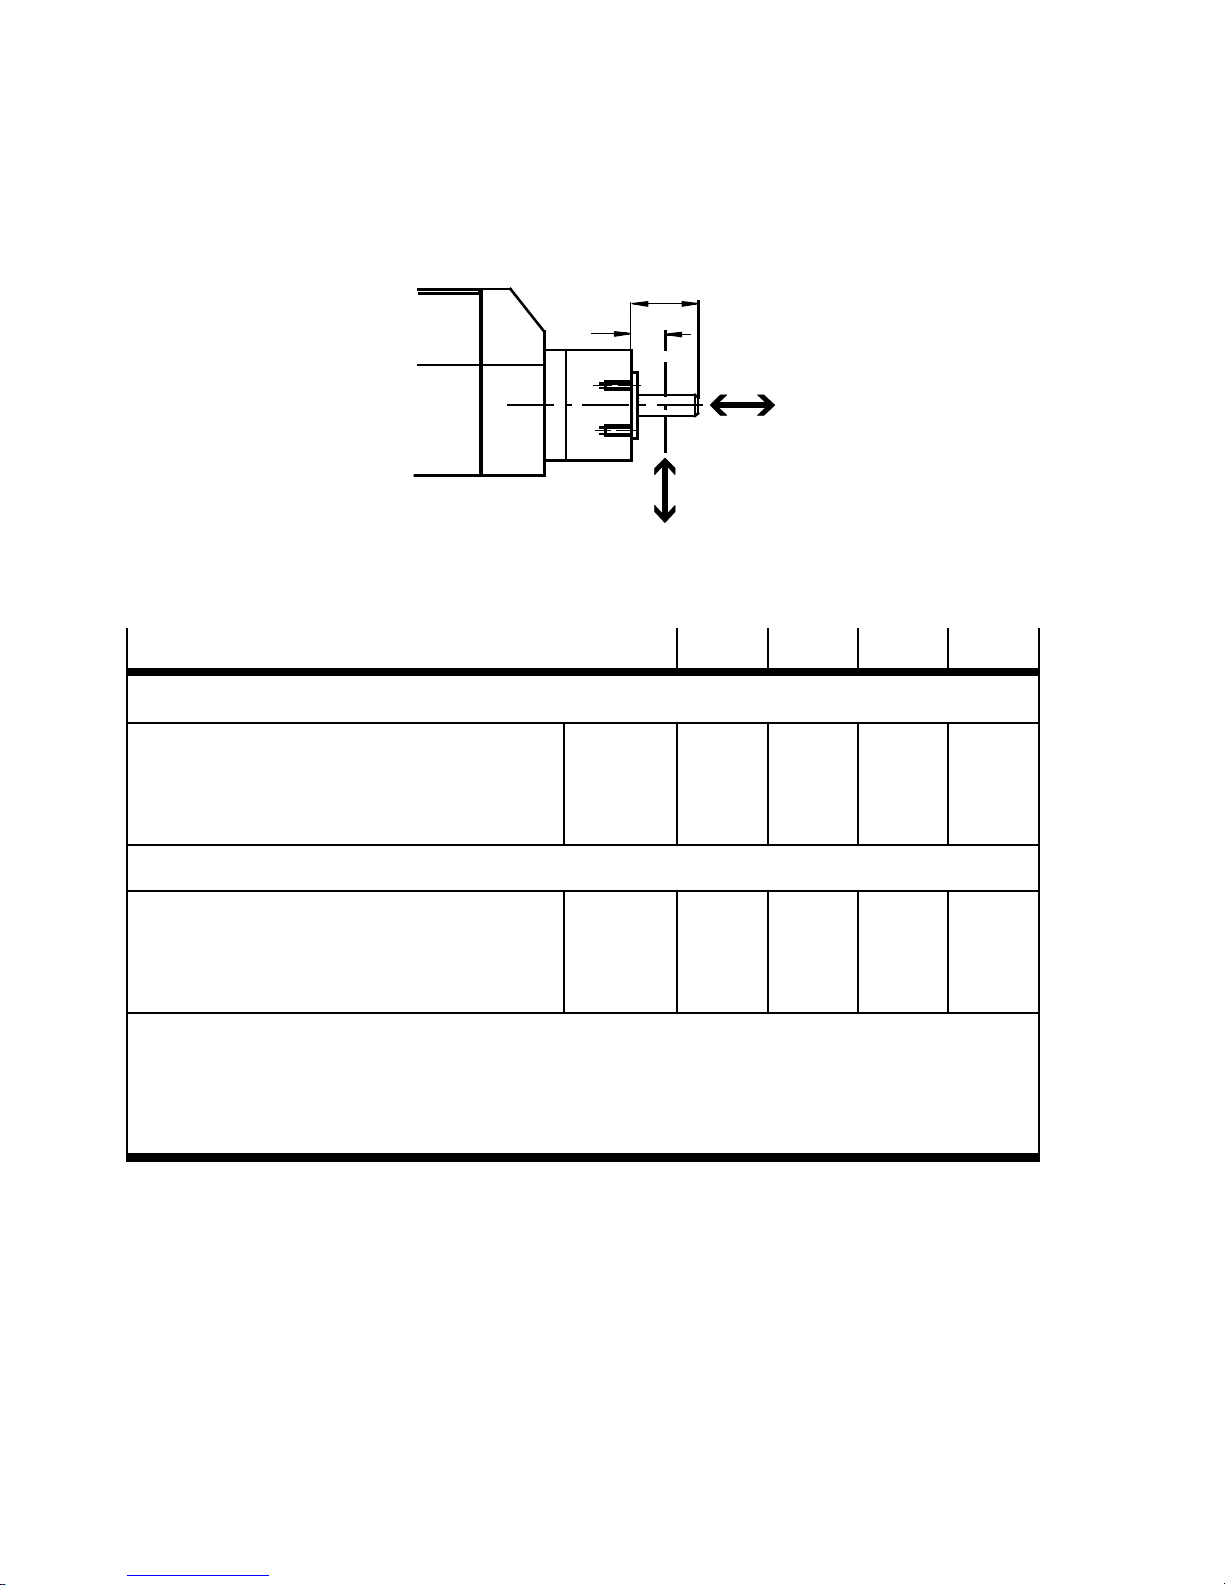
Make sure that you observe the maximum permitted values of the following variables: the basis point for forces
and torques is the centre of the shaft (L3 see Tab. 2/1).
Festo P.BE-MTR-DCI-IO-EN en 1209d
2-5
Page 40
2. Mounting
L3
F
Fig. 2/1: Forces and torques
L3 x 0.5
y
F
x
Forces and torques
32 42 52 62
MTR-DCI-...-G7 1-stage
– Radial shaft load
– Axial shaft load
– Maximum permitted shaft output torque of
the gear
1)
Fy[N]
F
[N]
x
Mx [Nm]
40
10
0.4
160
50
0.8
200
60
2.0
MTR-DCI-...-G14 /G22 2-stage
– Radial shaft load
– Axial shaft load
– Maximum permitted shaft output torque of
the gear
1)
With operating factor cb = 1.0 (3 hours operation daily, no shocks, direction of rotation constant).
1)
Fy[N]
F
[N]
x
M
[Nm]
x
70
20
1.0
230
80
7.5
320
100
12.0
The gear output torque or the motor unit is usually much lower, see Technical specifications,
appendix A, Mechanical specifications.
2)
MTR-DCI-62...-G22: In the start-up phase speed torque peaks up to 37 Nm are possible at 20 A
peak current.
Tab. 2/2: Permitted loading of the gear shaft
240
50
4
360
70
25
2)
2-6
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 41
2. Mounting
Note
Motor unit MTR-DCI-62...-G22 can generate up to 37 Nm at
a peak current of 20 A in the start-up phase.
•
Make sure by calculating the dynamic loading that the
maximum permitted shaft output torque of the gear is
not exceeded in the start-up phase (e.g. by reducing the
load).
Use the thread on the front of the gear (see Fig. 2/2) for
mounting the MTR-DCI to a mechanical drive device (machine
frame).
•
In order to minimize the shaft offset: Position the axis with
the aid of the centring diameter (D1 or D3 see Tab. 2/1)
relative to the rotary axis of the mechanism to be driven.
•
Fasten the motor unit with 4 screws and tighten the
4 screws with the specified tightening torque.
Motor unit MTR-DCI-32 has 6 threads for different mounting
variants (axial, parallel); 4 screws must be used here.
Size
MTR-DCI-32 M3 6mm 1.2 Nm
MTR-DCI-42 M3 7mm 1.2 Nm
MTR-DCI-52 M5 10 mm 5.9 Nm
MTR-DCI-62 M5 10 mm 5.9 Nm
Thread depth Tightening torque
M4 10 mm 2.9 Nm
Festo P.BE-MTR-DCI-IO-EN en 1209d
Tab. 2/3: Tightening torques
2-7
Page 42
2. Mounting
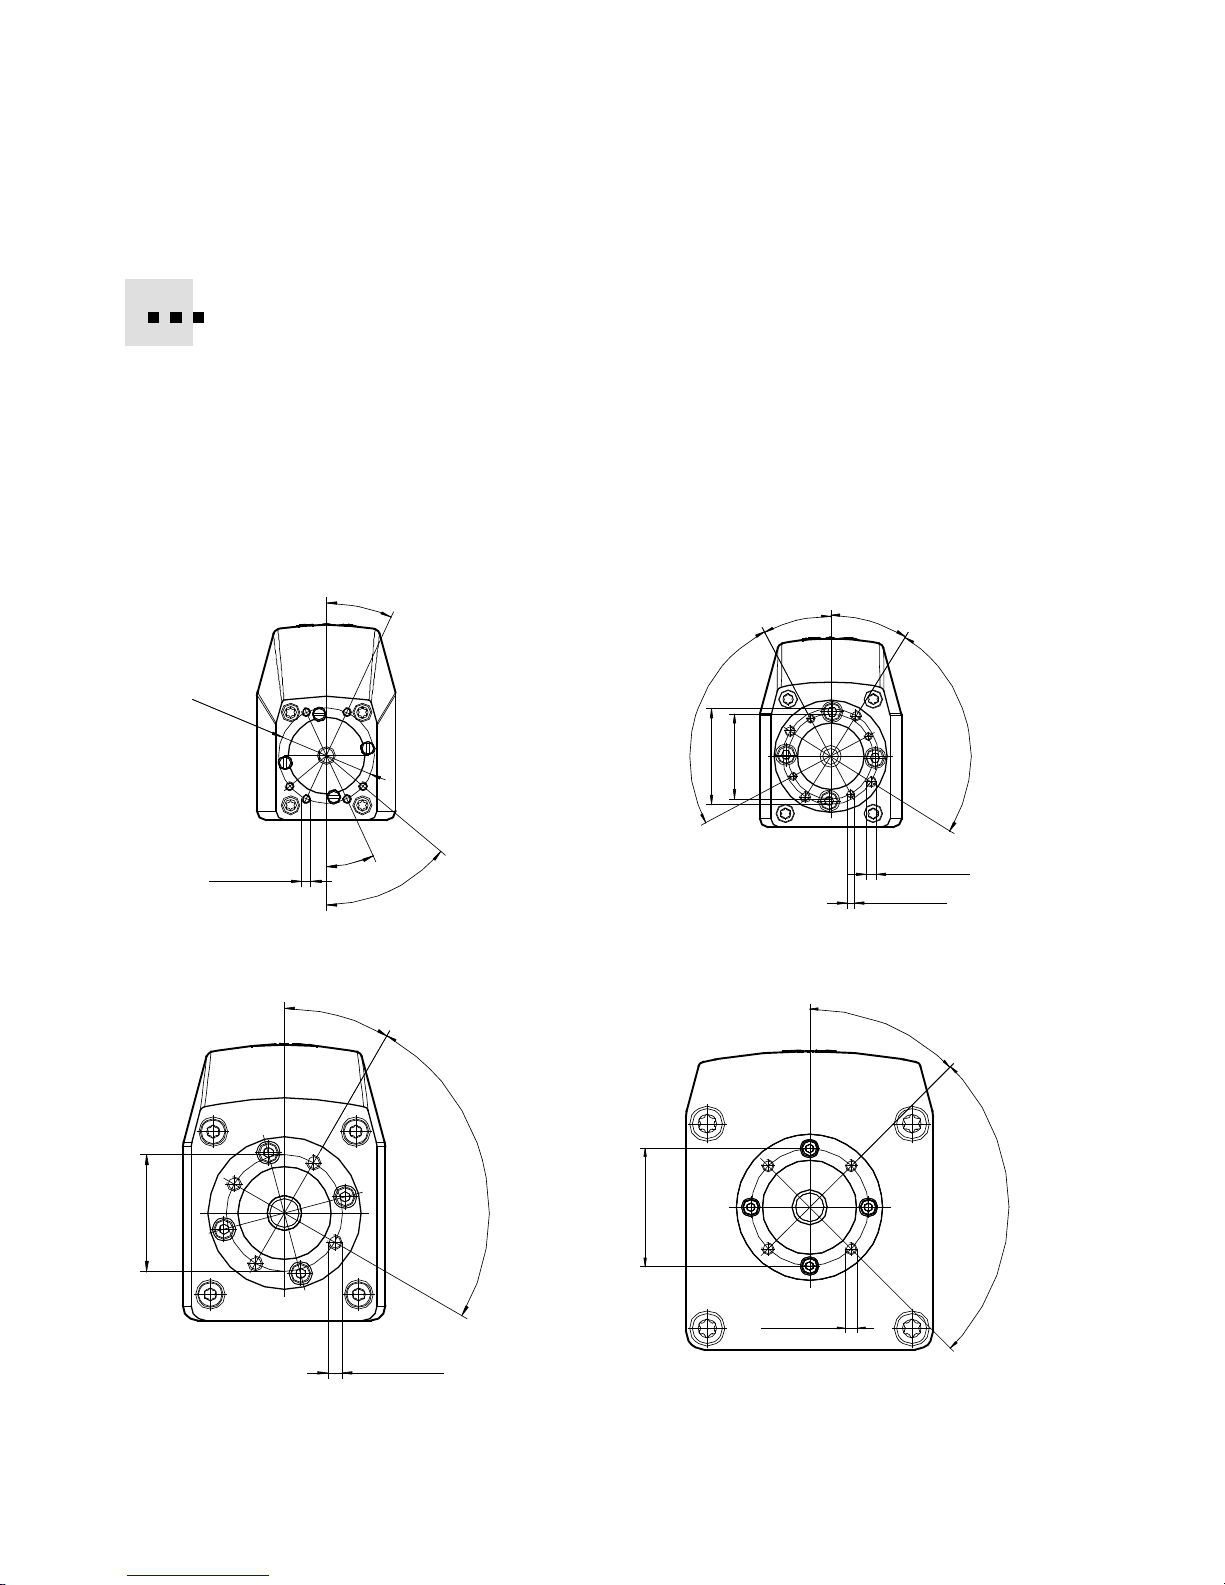
In order to fit Festo axes e.g. DMES or DGE axially, you will
require couplings and coupling housings as accessories. The
motor unit is connected to the axis by means of a clamp in the
coupling housing. Additional motor flanges are not therefore
necessary.
Fit the motor onto the permitted axis in accordance with the
Øassembly instructions for the motor mounting kit recommended in the catalogue.
Ø32
6xM3x6
MTR-DCI-32
25°
25°
MTR-DCI-52
30°
50°
4x 90°
MTR-DCI-42
28°
Ø36
Ø32
32°
4x 90°
4xM4x10
4xM3x7
MTR-DCI-62
45°
Ø40
4xM5x10
Fig. 2/2: Fastening the drive by means of the front threads (direct fastening)
2-8
4x 90°
4X 90°
Ø50
4xM5x10
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 43
Installation
Chapter 3
Installation
Festo P.BE-MTR-DCI-IO-EN en 1209d
3-1
Page 44
3. Installation
Contents
3. Installation 3-1...................................................
3.1 Overview of installation 3-3..........................................
3.2 Earthing 3-6.......................................................
3.3 Power supply 3-7..................................................
3.4 Serial interface 3-10.................................................
3.5 Input for external reference switch 3-12.................................
3.6 Connecting the higher-order controller 3-14..............................
3-2
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 45
3. Installation
3.1 Overview of installation
Warning
Before carrying out installation and maintenance work
always switch off the power supply for the electronic
components.
You can thereby avoid:
– unexpected movements of the connected actuators
– non-defined switching states of the electronic
components.
Caution
Faulty pre-assembled lines may destroy the electronics
and trigger unexpected movements of the motor.
•
For cabling the electric components of the system, use
only the cables listed as accessories (see Tab. 3/2). This
is the only way to ensure the system will work properly.
Caution
Earth or ground loops can under circumstances cause EMC
protective measures to become ineffective, resulting in
high compensating currents which will damage the motor
unit (e.g. with faulty power supply).
•
Connect only one cable shield (control cable or supply
cable) to functional earth (FE).
The GND connection must not be connected to the hous-
ing, the shield or functional earth (FE)!
Festo P.BE-MTR-DCI-IO-EN en 1209d
3-3
Page 46
3. Installation
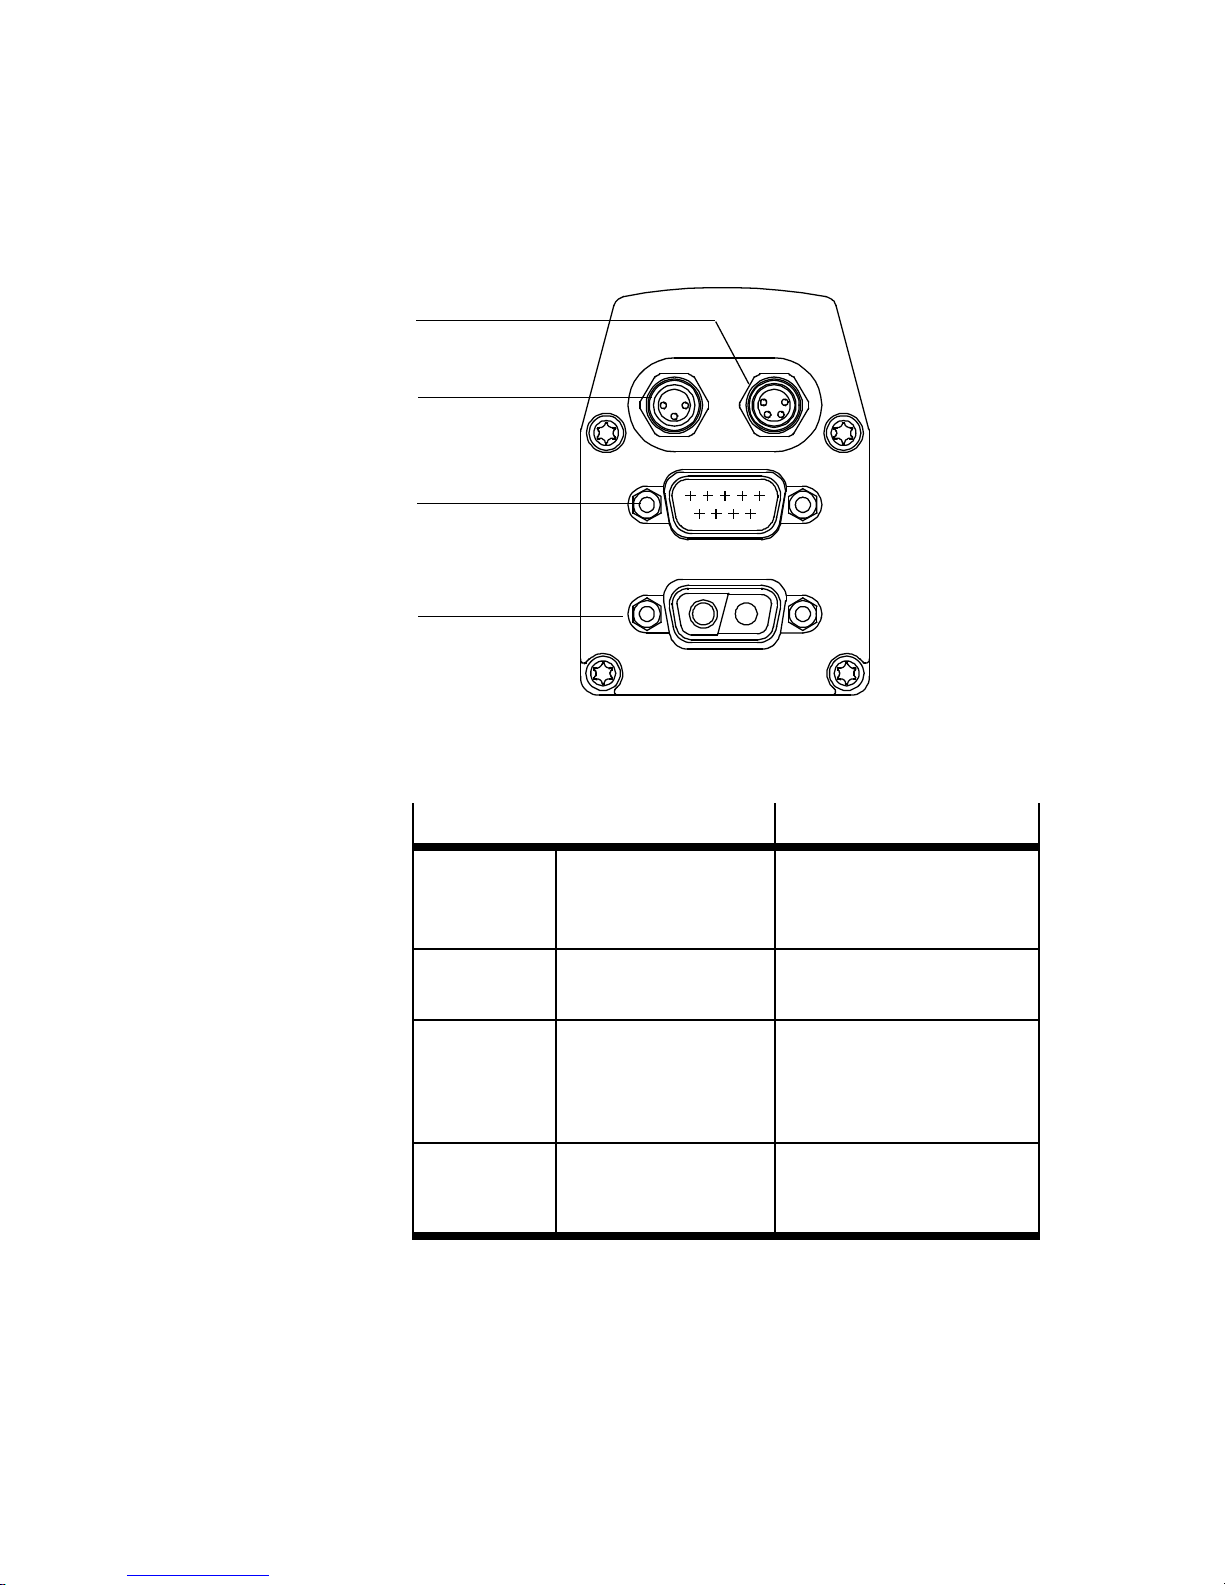
1
Power supply
2
I/O control
3
Reference switch
4
3
4
Serial interface
2
1
Fig. 3/1: Connections on the MTR-DCI
ConnectionontheMTR-DCI
Power supply – D-Sub, 2-pin
–Plug
Manual
Operating voltage connection with 2 high-current
contacts
3-4
Controller – D-Sub, 9-pin
–Plug
Reference
switch
Serial
interface
– M8x1, 3-pin
–Socket
– M8x1, 4-pin
–Socket
Tab. 3/1: Overview of connections
Festo P.BE-MTR-DCI-IO-EN en 1209d
Interface for connection to
any PLC controller
Sensor input for switch
type normally open contact
in the design PNP, e.g.
SMT-8F
RS232 interface for parametrizing, commissioning
and diagnosing
Page 47
3. Installation
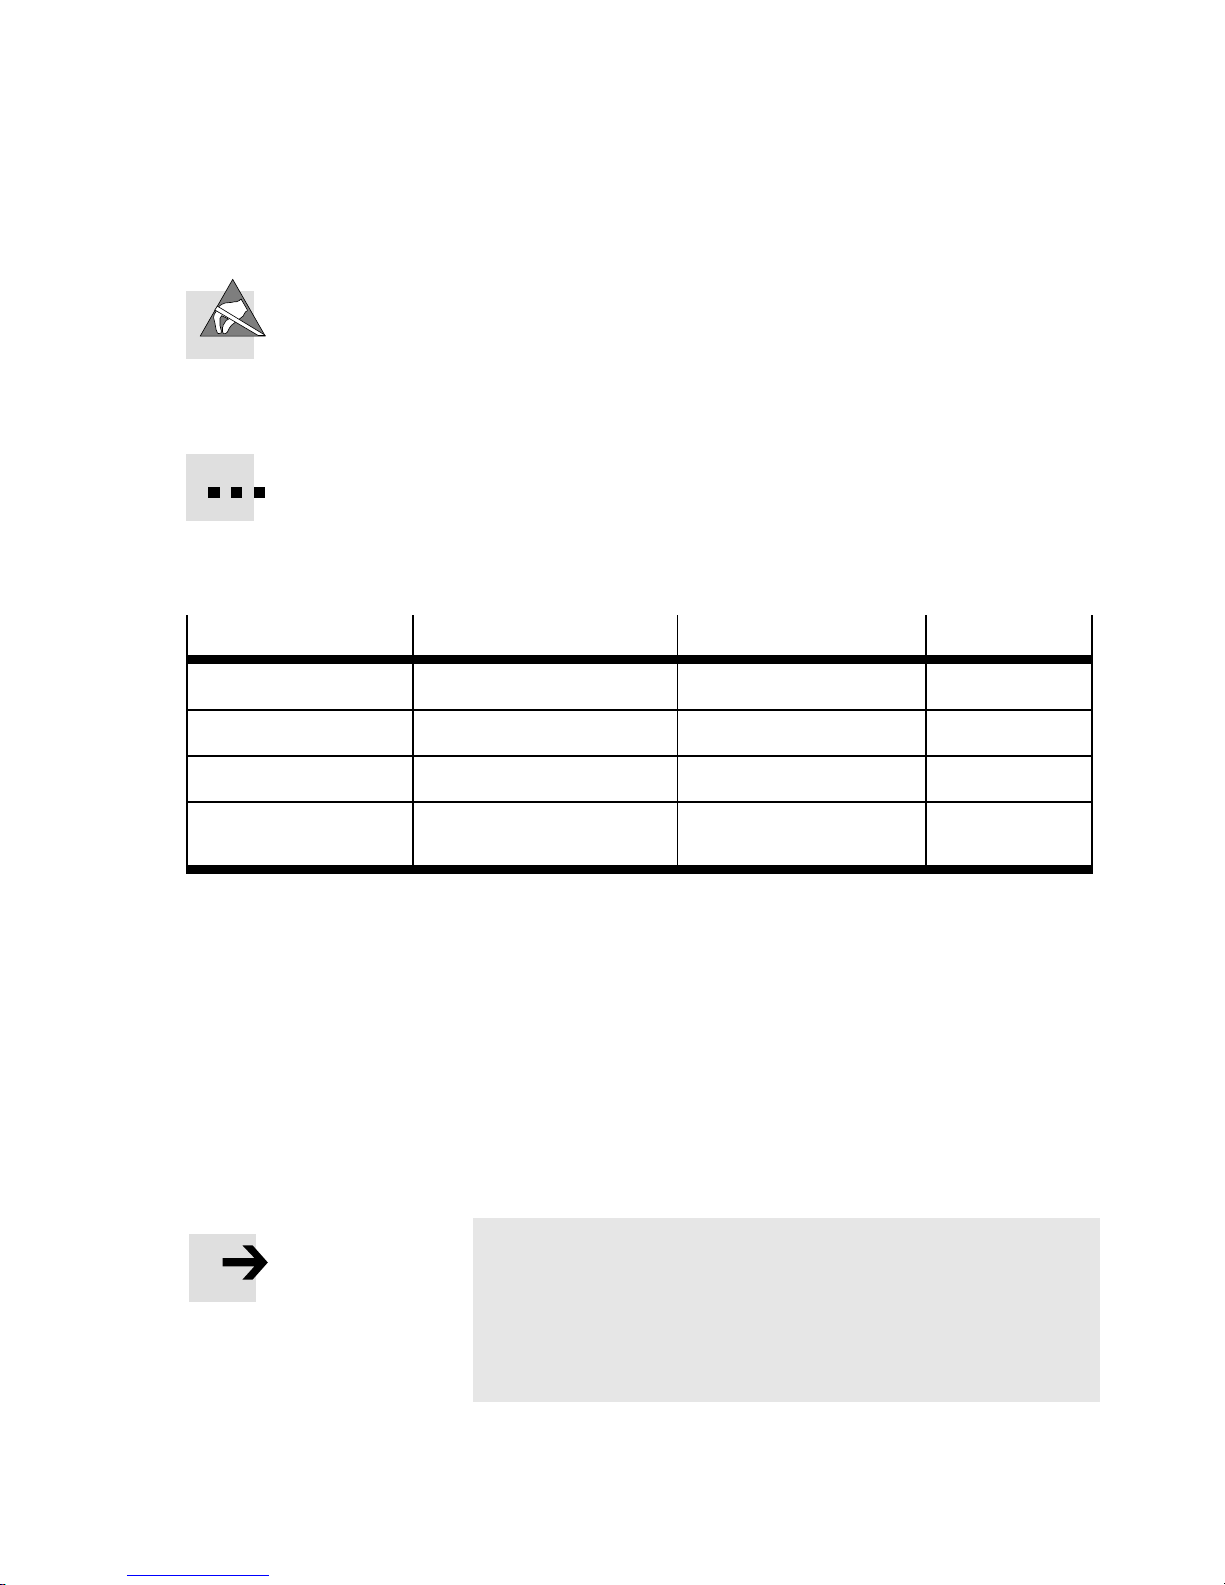
If non-assigned plug connectors are touched, there is a
danger that damage may occur to the MTR-DCI or to other
parts of the system as a result of ESD (electrostatic discharge). Place protective caps on unused connections in
order to prevent such discharges.
The plug connectors of the following Festo cables have been
designed so that, when inserted and screwed tight, or if fitted
with protective covers, the connections on the MTR-DCI will
comply with protection class IP54.
Connection
Voltage supply Power supply cable KPWR-MC-1-SUB-9HC 2.5/5/10
I/O control Pilot line KES-MC-1-SUB-9HC 2.5/5/10
Serial interface Programming cable KDI-MC-M8-SUB-9 2.5
Homing Switch If necessary, connecting
Cable Designation Length [m]
KM8-M8-GSGD 0.5/1/2/5
cable with screw-type lock
Tab. 3/2: Overview of cables (accessories)
In order to guarantee compliance with the IP protection class:
•
Seal unused M8 connections with ISK-M8 protective caps
(accessories).
•
Hand-tighten the union nuts/locking screws of the plugs.
Observe the permissible tightening torques specified in
the documentation for the lines and plugs used.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Note
•
Lay all moveable motor and sensor cables free of bends
and free of mechanical stress, if necessary, in a drag
chain.
•
Observe the maximum specified cable lengths.
3-5
Page 48
3. Installation
3.2 Earthing
Note
•
Connect the earth terminal of the MTR-DCI with low impedance (short cable with large cross section) to the
earth potential.
This prevents interference from electromagnetic sources
and ensures electromagnetic compatibility in accordance
with EMC directives.
In order to connect the MTR-DCI to the earth potential, use
exclusively the following earth terminal:
– Earthing strap on free end of the power supply cable; see
assembly instructions for cable KPWR-MC-1-SUB-9HC-...
Caution
Earth or mass loops can make EMC safety measures ineffective and allow high compensating currents to destroy
the motor unit.
•
Connect only the cable screening of the power supply
cable to the functional earth FE.
•
Do not connect the terminal GND with the housing,
screening, or functional earth FE!
•
Never connect one of the power supply connections (see
chapter 3.2, A1, A2) with FE or with the housing.
This will avoid damaging the device and impairing protection against electromagnetic interference (EMC).
3-6
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 49
3. Installation
3.3 Power supply
Warning
•
In order to provide the electric power supply, use only
PELV circuits as per IEC/DIN EN 60204-1 (Protective
Extra-Low Voltage, PELV).
Take into account also the general requirements for
PELV circuits as per IEC/DIN EN 60204-1.
•
Use only power packs which guarantee reliable electri-
cal isolation of the operating voltage as per IEC/DIN
EN 60204-1.
By the use of PELV power units, protection against electric
shock (protection against direct and indirect contact) is guaranteed in accordance with IEC/DIN EN 60204-1 (electrical
equipment of machines, general requirements).
Caution
Damage to the device.
The voltage input of the motor unit has no special protec-
tion against overvoltage.
•
Make sure that the permitted voltage tolerance is not
exceeded. The tolerance must also be observed directly
at the operating voltage connection of the MTR-DCI
(see Tab. 3/3).
•
Install an external fuse in the DC supply in order to limit
the available current (see Tab. 3/4).
Festo P.BE-MTR-DCI-IO-EN en 1209d
3-7
Page 50
3. Installation
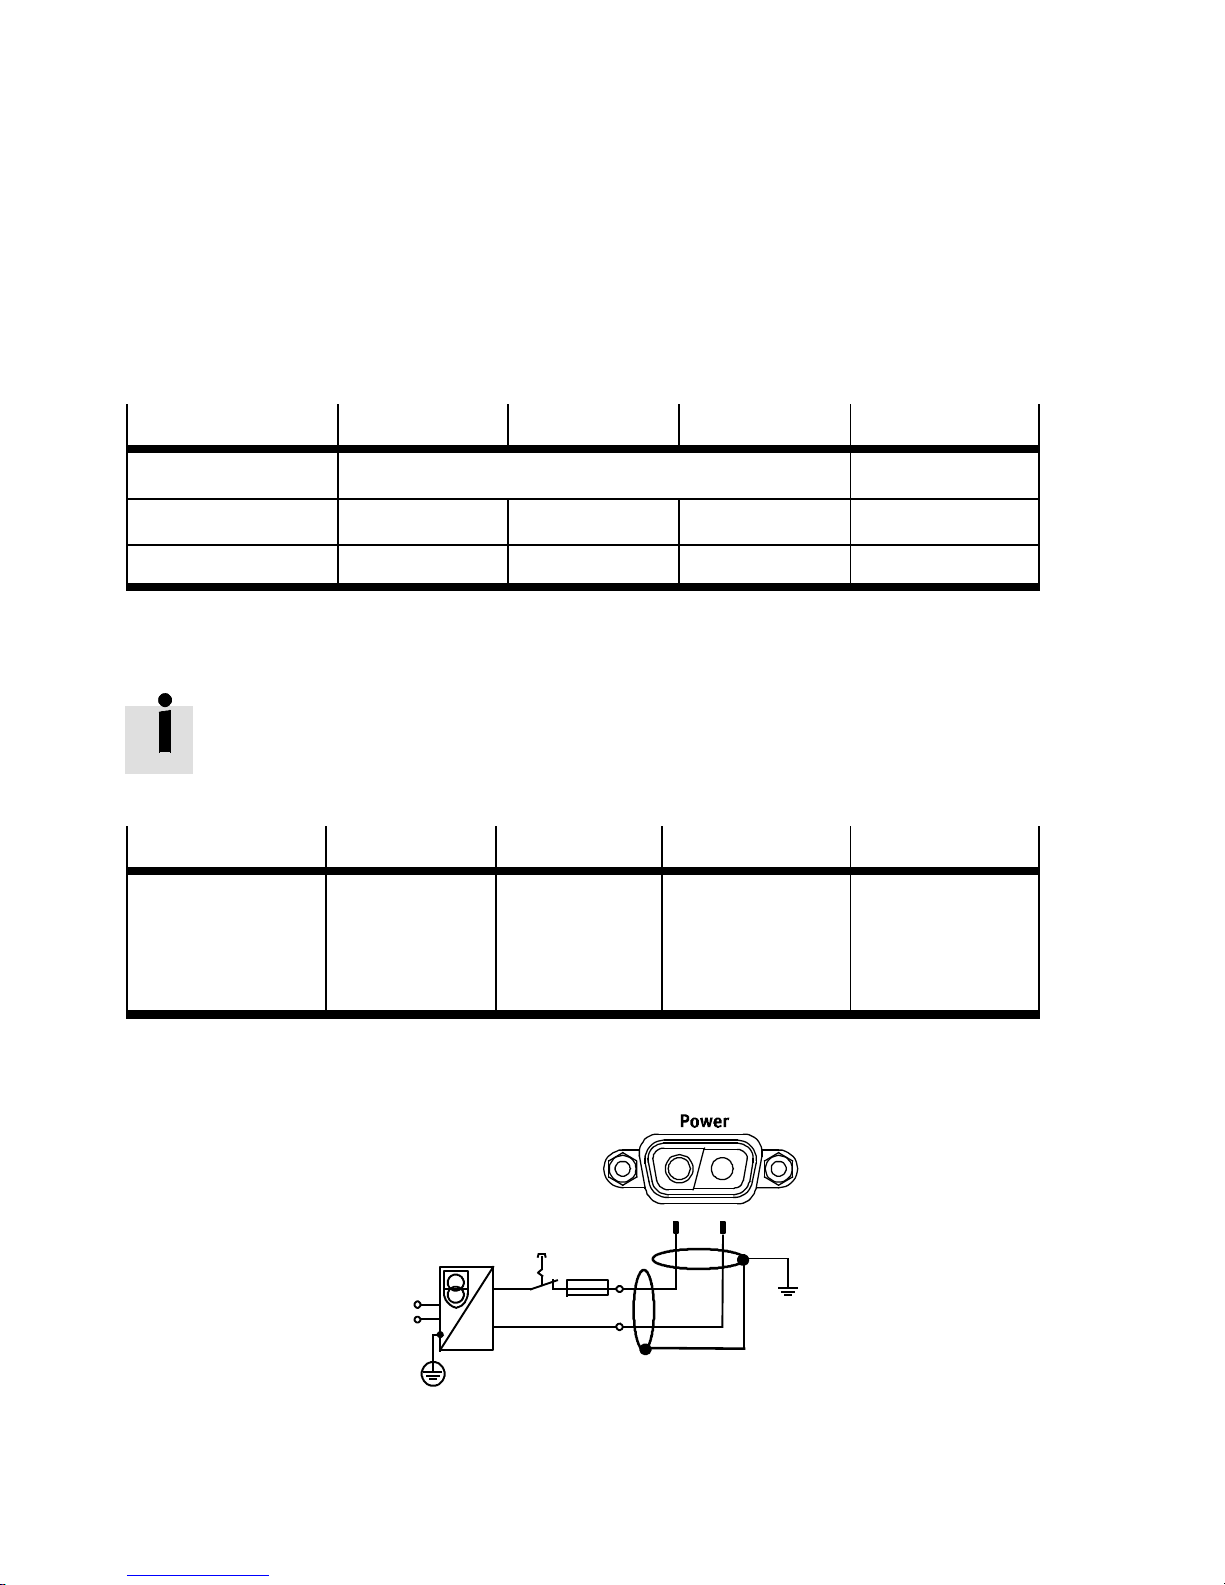
The internal power and controller electronics are supplied
with DC voltage via the power supply connection. The power
supply must fulfil the following requirements:
Specifications
Rated voltage DC 24 V ±10 % DC 48 V +5...-1 %
Rated current 0.73 A ±20 % 2A±20% 5A±20% 6.19 A ±20 %
Peak current 2.1A±20% 3.8A±20% 7.7A±20% 20 A ±20 %
MTR-…-32 MTR-…-42 MTR-…-52 MTR-…-62
Tab. 3/3: Power supply
Recommendation
Use a closed-loop controlled power unit with high output
reserve and external fuse:
MTR-…-32 MTR-…-42 MTR-…-52 MTR-…-62
Power unit (closedloop controlled)
External fuse
secondary side
DC 24 V /3 A DC 24 V/ 6 A DC 24 V/ 10 A DC 48 V / 20 A
5 A slow-blowing 7 A slow-blowing 10 A slow-blowing 25 A slow-blowing
Tab. 3/4: Selecting the power unit
3-8
A1 A2
A1 A2
Fig. 3/2: Connection example – power supply with external
fuse
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 51
3. Installation
•
Use the following cable from Festo's accessories:
– power supply cable KPWR-MC-1-SUB-9HC
– cable length max. 10 m.
•
Only connect one cable screen (control cable or power
supply cable) to the functional earth (FE).
Plug
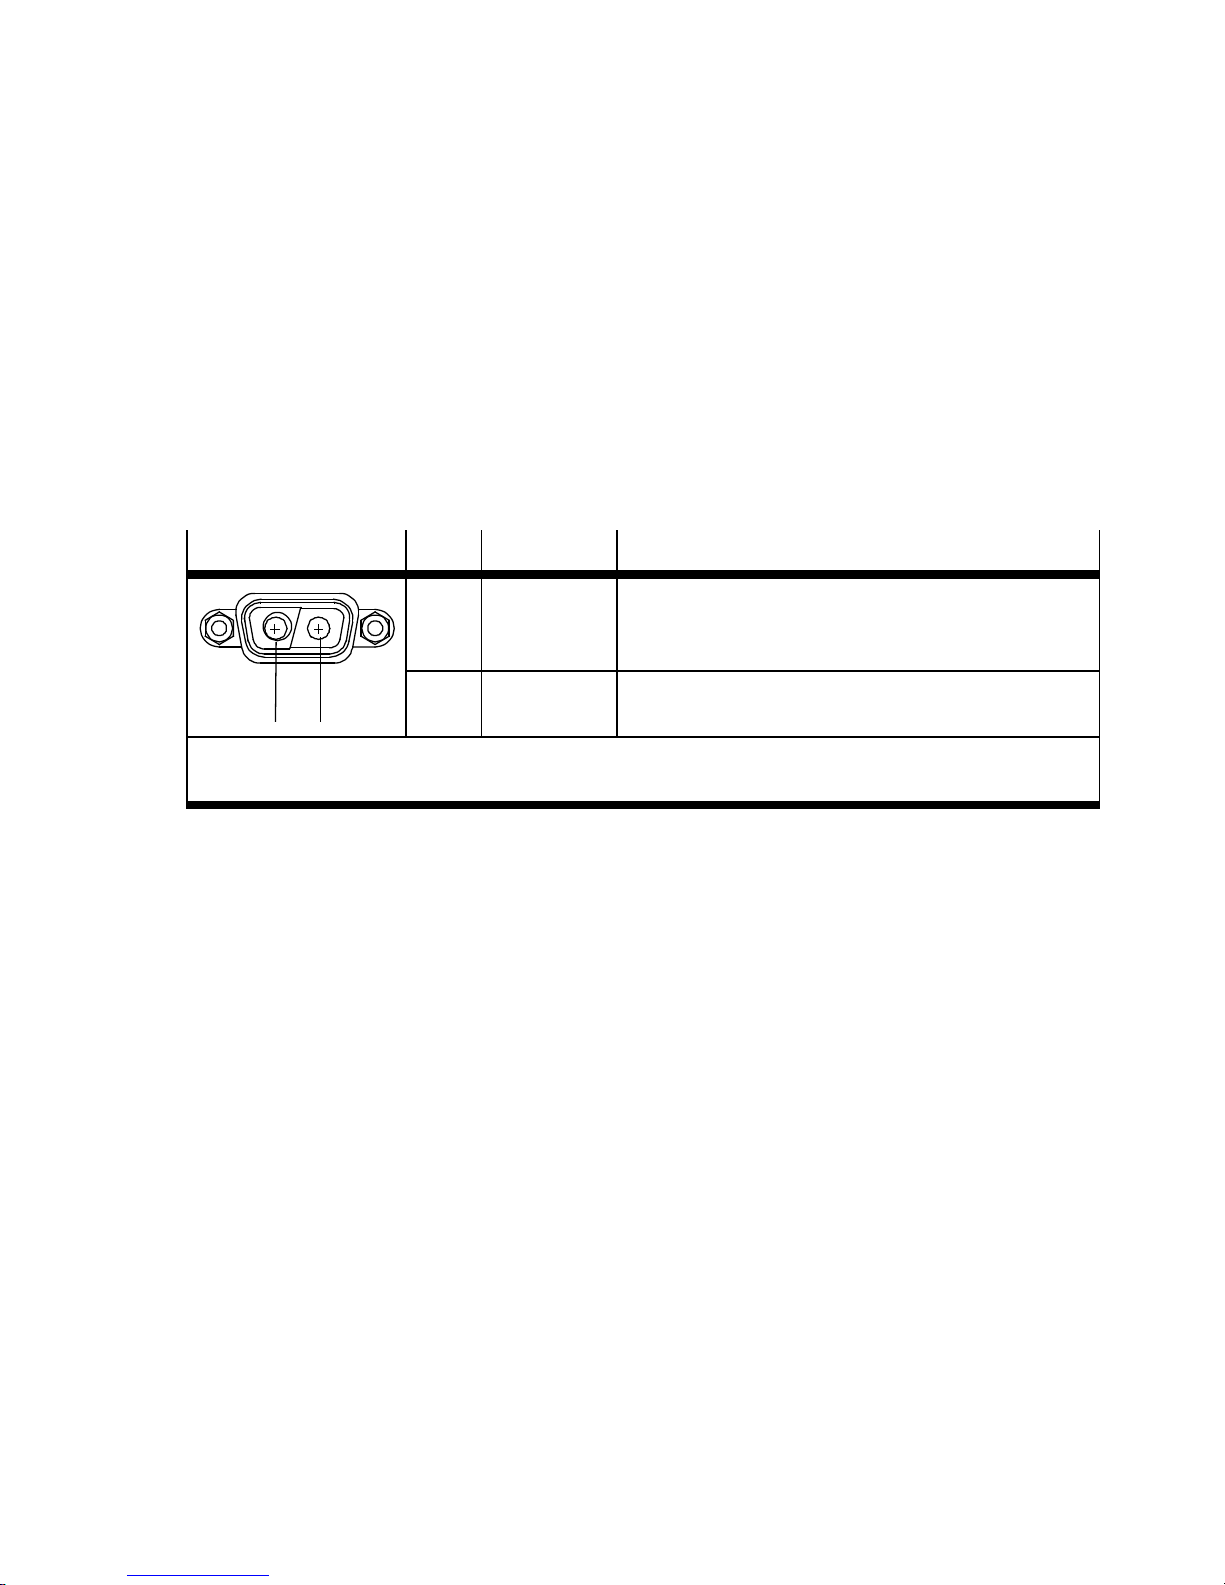
A1
1)
Cable colours with power supply cable KPWR-MC-1-SUB-9HC
2)
Do not link the GND terminal to any housing, screen or functional earth (FE)!
A2
Pin Colour
A1 black (1) MTR-DCI-32/42/52:
A2 black (2) MTR-DCI-32/42/52/62: POWER GND
1)
Manual
MTR-DCI-62:
Tab. 3/5: Connecting the power supply to the motor unit
POWER D C +24 V
POWER D C +48 V
2)
Festo P.BE-MTR-DCI-IO-EN en 1209d
3-9
Page 52
3. Installation
3.4 Serial interface
Serial interface for parametrizing, commissioning and
diagnosing
Note
To connect a PC to the MTR-DCI, use the following cable
from Festo's accessories:
– Programming cable KDI-MC-M8-SUB-9
– Cable length 2.5 m (maximum permitted signal cable
length).
•
If necessary, remove the protective cap from the serial
interface of the MTR-DCI.
•
Connect the following terminals with the programming
cable:
– the connection socket on the MTR-DCI
– a serial interface COMx of the diagnostic PC.
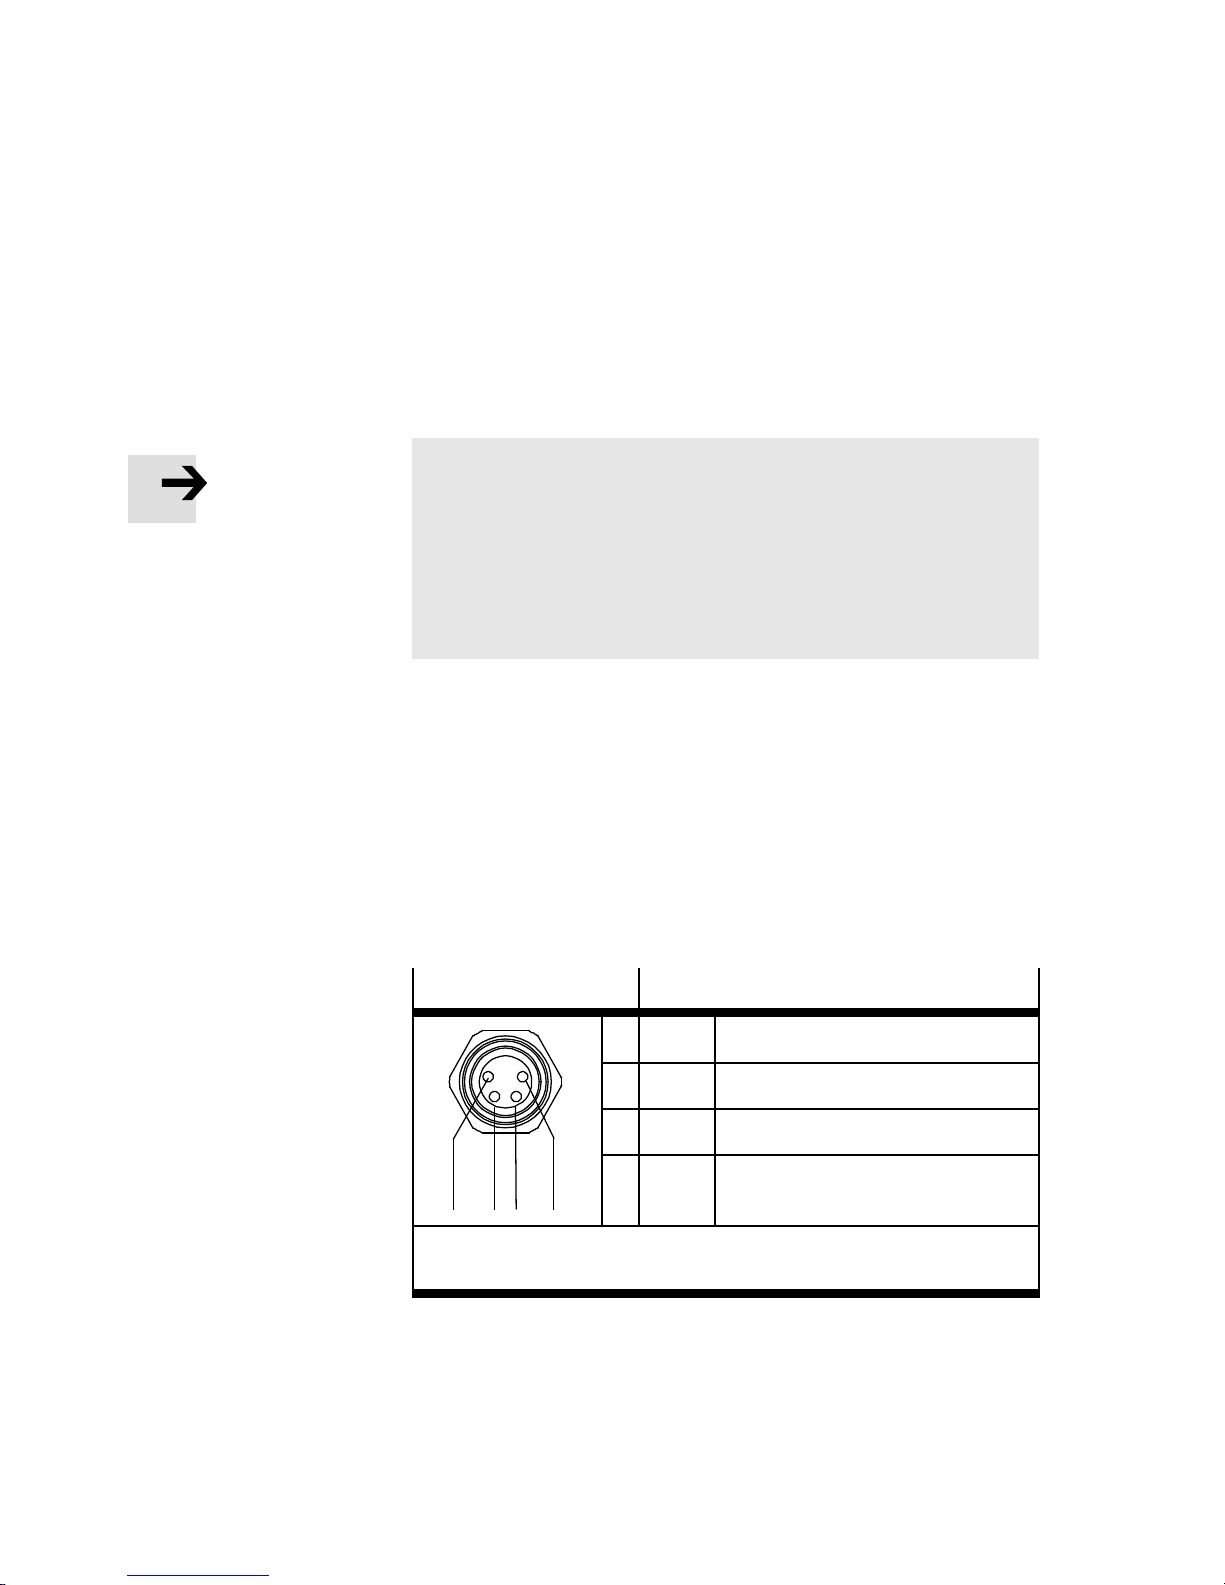
M8x1 socket
1243
1)
The levels correspond to the RS232 standard and enable a data
transmission rate of 9600 bit/s
Description
1 GND Ground
2 TXD RS232 transmitting cable
3 RXD RS232 receiving cable
4 --- Reserved for service personal.
Do not connect.
1)
1)
3-10
Tab. 3/6: Connecting the serial interface on the MTR-DCI
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 53
3. Installation
Information on commissioning and parametrizing the
MTR-DCI via the serial interface can be found in chapter 5.3
and in the help system for the FCT software package.
Information on transmitting CI commands via the serial
interface can be found in appendix B.1.2.
Note
The RS232 interface is not electrically isolated. It is not
suitable for permanent connection to PC systems, nor for
use as a control interface.
•
Use this terminal only for commissioning.
•
Remove the programming cable in continuous opera-
tion.
•
Seal the terminal with the supplied protective cap (ISK-
M8).
Festo P.BE-MTR-DCI-IO-EN en 1209d
3-11
Page 54
3. Installation
3.5 Input for external reference switch
If you are not using a reference switch:
•
Seal the connection with the protective cap supplied
(ISK-M8).
Connecting the reference switch:
•
Use the correct switch type “normally-open contact” in
the PNP variant for the reference switch.
•
When connecting the reference switch use a sensor with a
screw-type lock (external thread M8x1) at the end of the
cableorusetheconnectingcableKM8-M8withascrewtype lock as an adapter.
Use e.g. the following proximity switches from Festo:
– magnetic proximity switch SMT-8F
– inductive proximity switch SIEN-...-M8B
•
When selecting the sensor, note that the accuracy of the
switchover point of the sensor determines the accuracy of
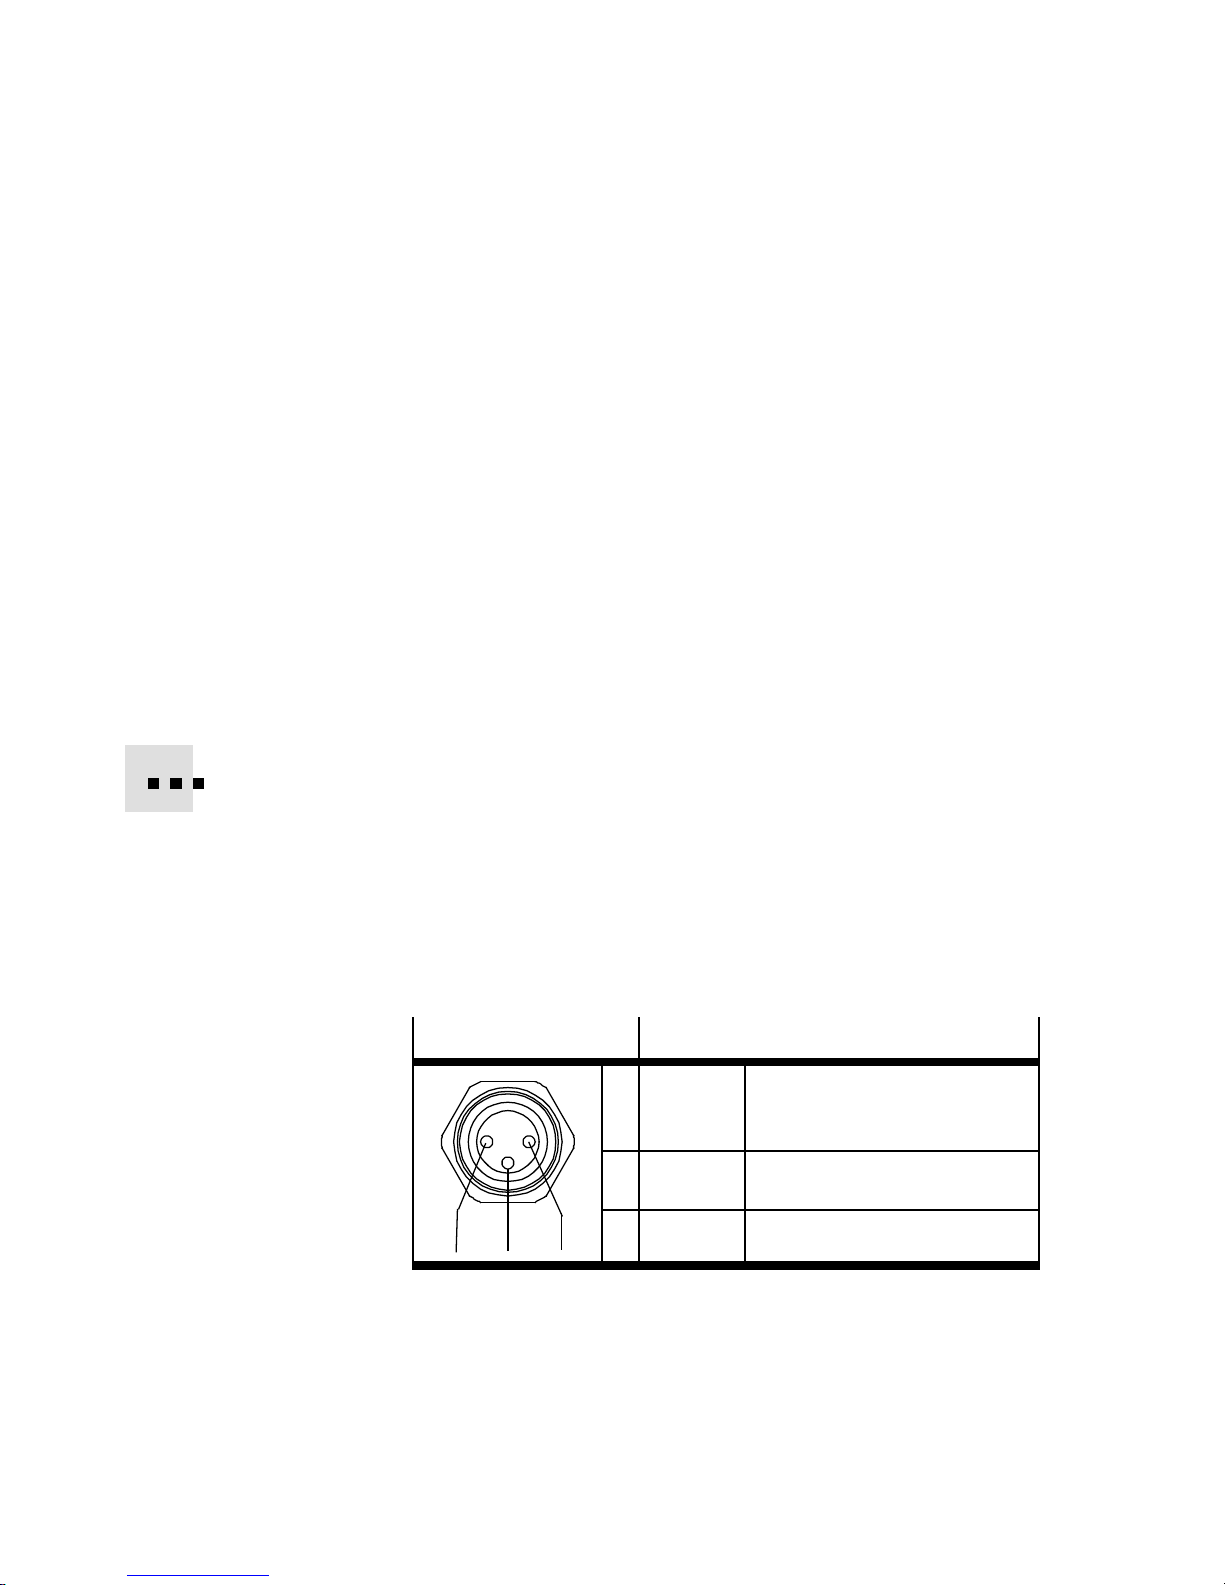
the reference point.
M8x1 socket
134
Description
1 DC +24 V DC +24 V voltage output
(only for reference switch)
4 REF Contact reference switch
3 GND Ground
Tab. 3/7: Connection “Ref” (reference switch) on the
MTR-DCI
3-12
The power supply for the reference switch (DC 24 V / Ground)
is provided via pin 1/3.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 55
3. Installation
Caution
Damage to the device
The DC 24 V voltage at pin 1 does not have any special
protection against overload; the voltage is taken from the
main supply with protection against ESD and incorrect
polarity.
•
Use this connection only for the reference switch
(sensor supply).
Use of this connection as a power supply for other devices
is not permitted.
The input for sensor signal REF complies in its electrical
features with the input specification in the appendix
“Technical specifications”.
Festo P.BE-MTR-DCI-IO-EN en 1209d
3-13
Page 56
3. Installation
3.6 Connecting the higher-order controller
Communication with the higher-order controller is made via
the control connection on the MTR-DCI
Use the control cable KES-MC-1-SUB-9 to connect the
MTR-DCI to a higher-level controller (PLC).
Caution
Long I/O signal cables reduce the immunity to interference.
•
Do not, therefore, exceed the maximum permitted I/O
signal cable length of 30 m.
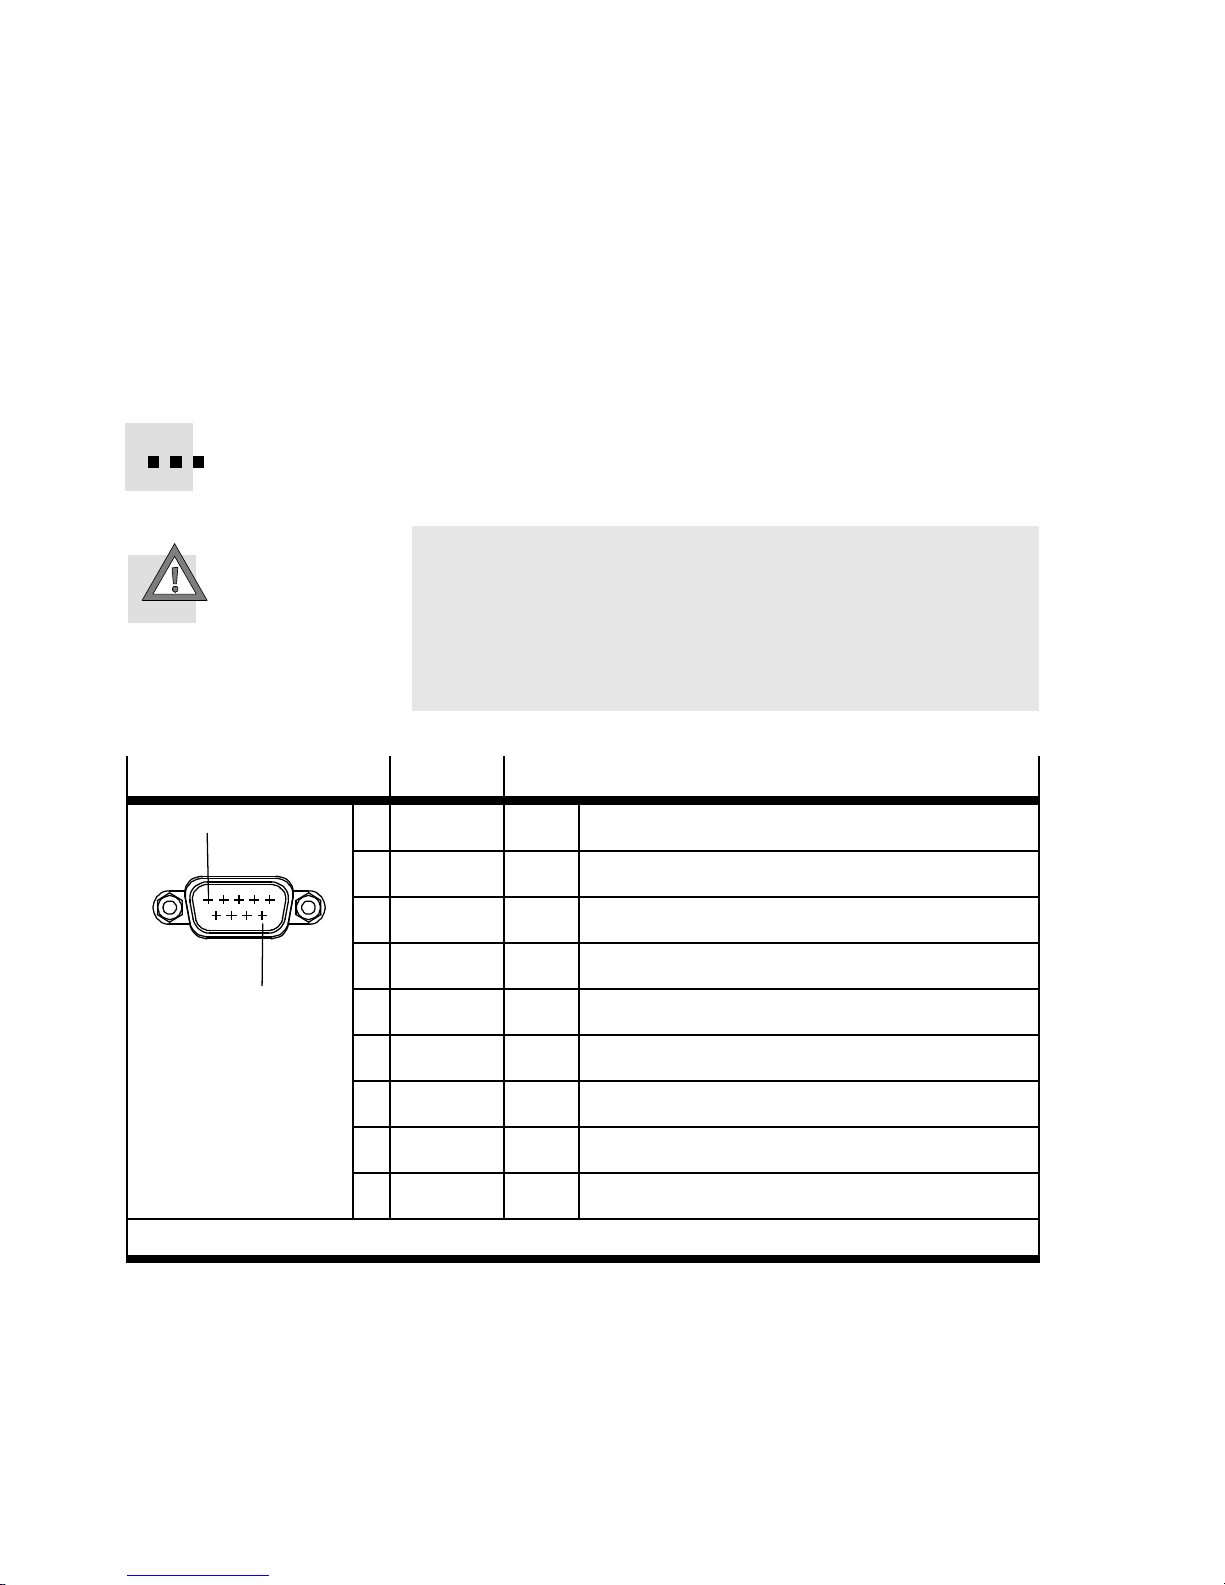
Sub-D plug
1
9
1)
Cable colours of pilot line KES-MC-1-SUB-9
Colour
1 white I1 Position set code Bit0
2 brown I2 Position set code Bit1
3 green I3 Position set code Bit2
4 yellow I4 Position set code Bit3
5 grey I5 START
6 pink I6 ENABLE
7 blue O1 READY
8 red O2 MOTION COMPLETE (MC)
9 black GND GROUND (basis potential)
1)
Description
Tab. 3/8: “Controll er” connection on the MTR-DCI
3-14
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 57
3. Installation
Warning
If a voltage is applied and the output pins are used incorrectly, the device may be seriously damaged, therefore:
•
Do not connect voltage to the outputs.
•
Note the current limit at the outputs.
Festo P.BE-MTR-DCI-IO-EN en 1209d
3-15
Page 58
3. Installation
3-16
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 59
Control panel (MTR-DCI-...-H2IO)
Chapter 4
Control panel (MTR-DCI-...-H2IO)
Festo P.BE-MTR-DCI-IO-EN en 1209d
4-1
Page 60
4. Control panel (MTR-DCI-...-H2IO)
Contents
4. Control panel (MTR-DCI-...-H2IO) 4-1.................................
4.1 Composition and function of the control panel 4-4.......................
4.2 The menu system 4-6...............................................
4.2.1 Accessing the main menu 4-6.................................
4.2.2 Menu [Diagnostic] 4-8.......................................
4.2.3 Menu [Settings] 4-11.........................................
4.2.4 Menu [Positioning] 4-17.......................................
4.2.5 Menu command [HMI control] 4-20.............................
4-2
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 61
4. Control panel (MTR-DCI-...-H2IO)
On the control panel, motor unit type MTR-DCI-...-H2 offers all
the functions necessary for commissioning, programming and
diagnosis. An overview of the button and menu functions for
the MTR-DCI-...IO can be found in this chapter. Commissioning with the control panel is described as from chapter 5.2.
With the MTR-DCI-...-R2 (without control panel) you can commission the MTR-DCI via the RS232 interface (with FCT software). Instructions on this can be found in chapter 5.3.
Caution
Faults may occur if you attempt to access control and
operating functions at the same time via the FCT and the
control panel.
•
Make sure that the FCT, the control panel and the control
interface of the MTR-DCI are not used at the same time.
Note
If necessary, remove the protective foil from the display
before commissioning.
Festo P.BE-MTR-DCI-IO-EN en 1209d
4-3
Page 62
4. Control panel (MTR-DCI-...-H2IO)
4.1 Composition and function of the control panel
The control panel enables commissioning directly on the
MTR-DCI with the following functions:
– Parametrizing and referencing the axis
– Entering position sets
– Test functions e.g. for moving to individual position sets.
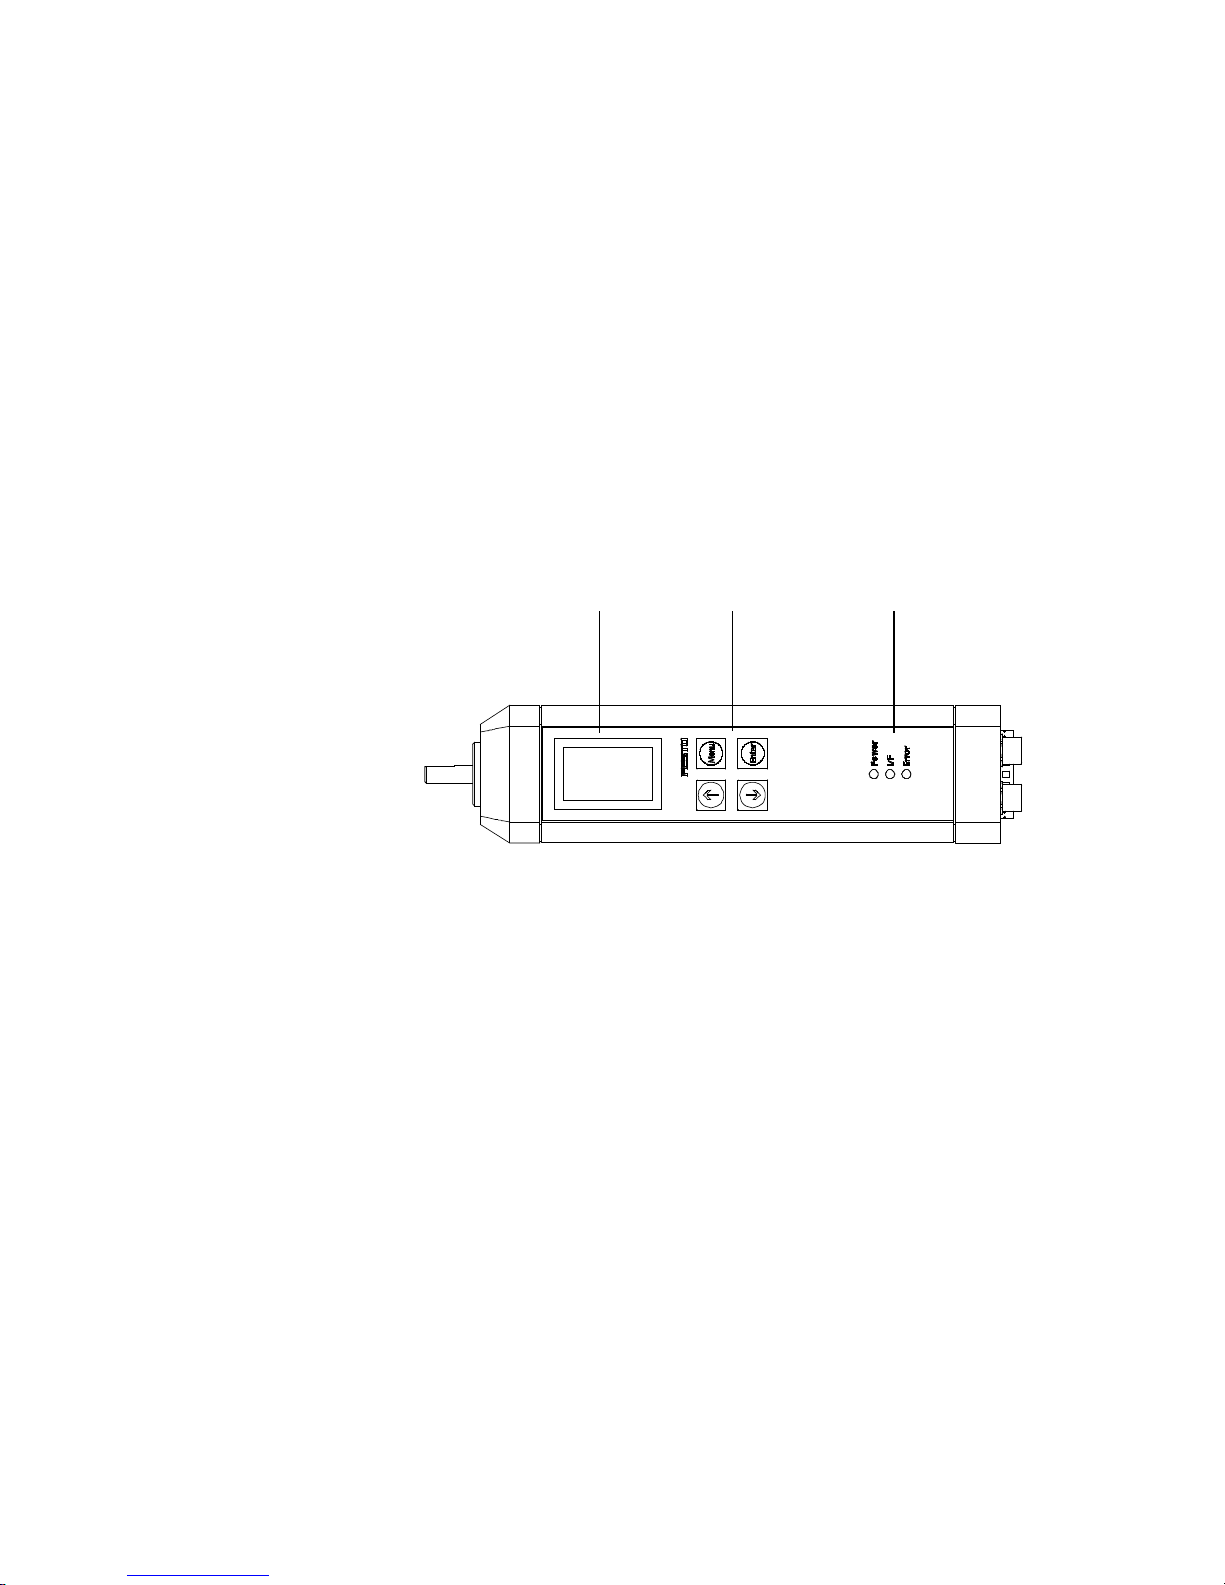
1
LC display
1
2
3
2
Operating buttons
3
LEDs
– Power (green)
– I/F (green/red)
– Error (red)
Fig. 4/1: Control panel of the MTR-DCI-...-H2
With the 4 buttons on the control panel you can carry out all
operating functions and settings as indicated in the menu.
The graphic LCD display shows all texts in English. The display can be turned in 90° steps, see menu command [LCD
adjustment].
The visual display of the operating states is shown via 3 LEDs
(see also chapter 6.2.2).
– Power: display of power supply
4-4
– I/F: ready to operate, positioning status
– Error: fault
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 63
4. Control panel (MTR-DCI-...-H2IO)
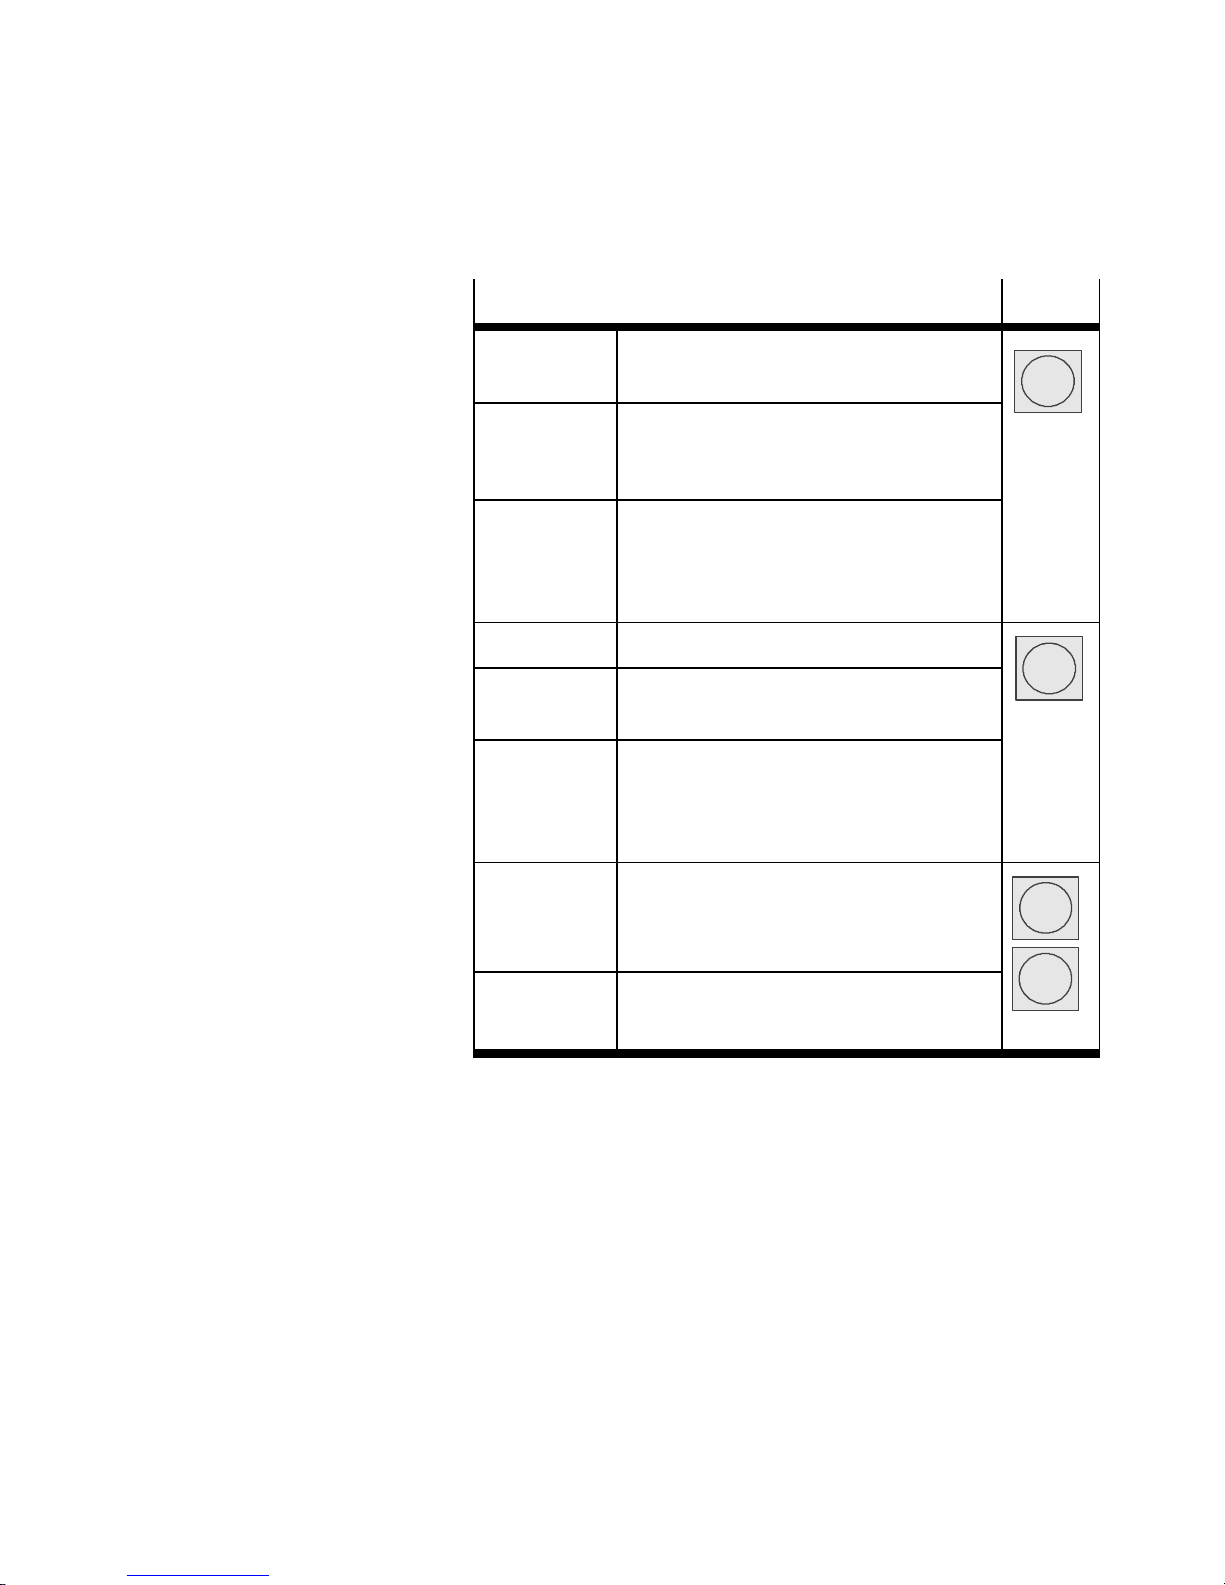
Function Button
MENU Activated by the status display from the
ESC Rejects the current entry and switches
EMERG.STOP Interrupts the current positioning
OK Confirms the current selection or entry
SAVE Saves parameter settings permanently in
main menu
back in stages to the higher-order menu
level or status display
procedure (> Error mode; confirm with
<Enter>, then automatic return to the
status display) Only when HMI = on.
the EEPROM
Menu
Enter
START/STOP Starts or stops a positioning procedure
(only in Demo mode). After stop: Display
the current position, return to the
higher-order menu level with <Menu>.
<- -> Scrolls within a menu level in order to
select a menu command.
EDIT Sets the parameter
Tab. 4/1: Button function (overview)
v
V
Festo P.BE-MTR-DCI-IO-EN en 1209d
4-5
Page 64
4. Control panel (MTR-DCI-...-H2IO)
4.2 The menu system
4.2.1 Accessing the main menu
MTR-DCI...
= 0.00 mm
X
a
HMI:off
<Menu>
} Diagnostic
positioning
Settings
S ESC <Menu>
<--> OK <Enter>
} HMI control
LCD adjustment
v ESC <Menu>
<--> OK <Enter>
When the power supply is switched on, the MTR-DCI automatically carries out an internal check. At first the display
briefly shows the Festo Logo then changes to the status
display. The status display shows the following information:
– the type designation of your MTR-DCI
– the current position of the drive x
a
= ...
– the current setting of the device control
(HMI = Human Machine Interface)
The main menu is accessed from the status display with the
button <Menu>. The current button function will be displayed
in the lower lines of the LCD display.
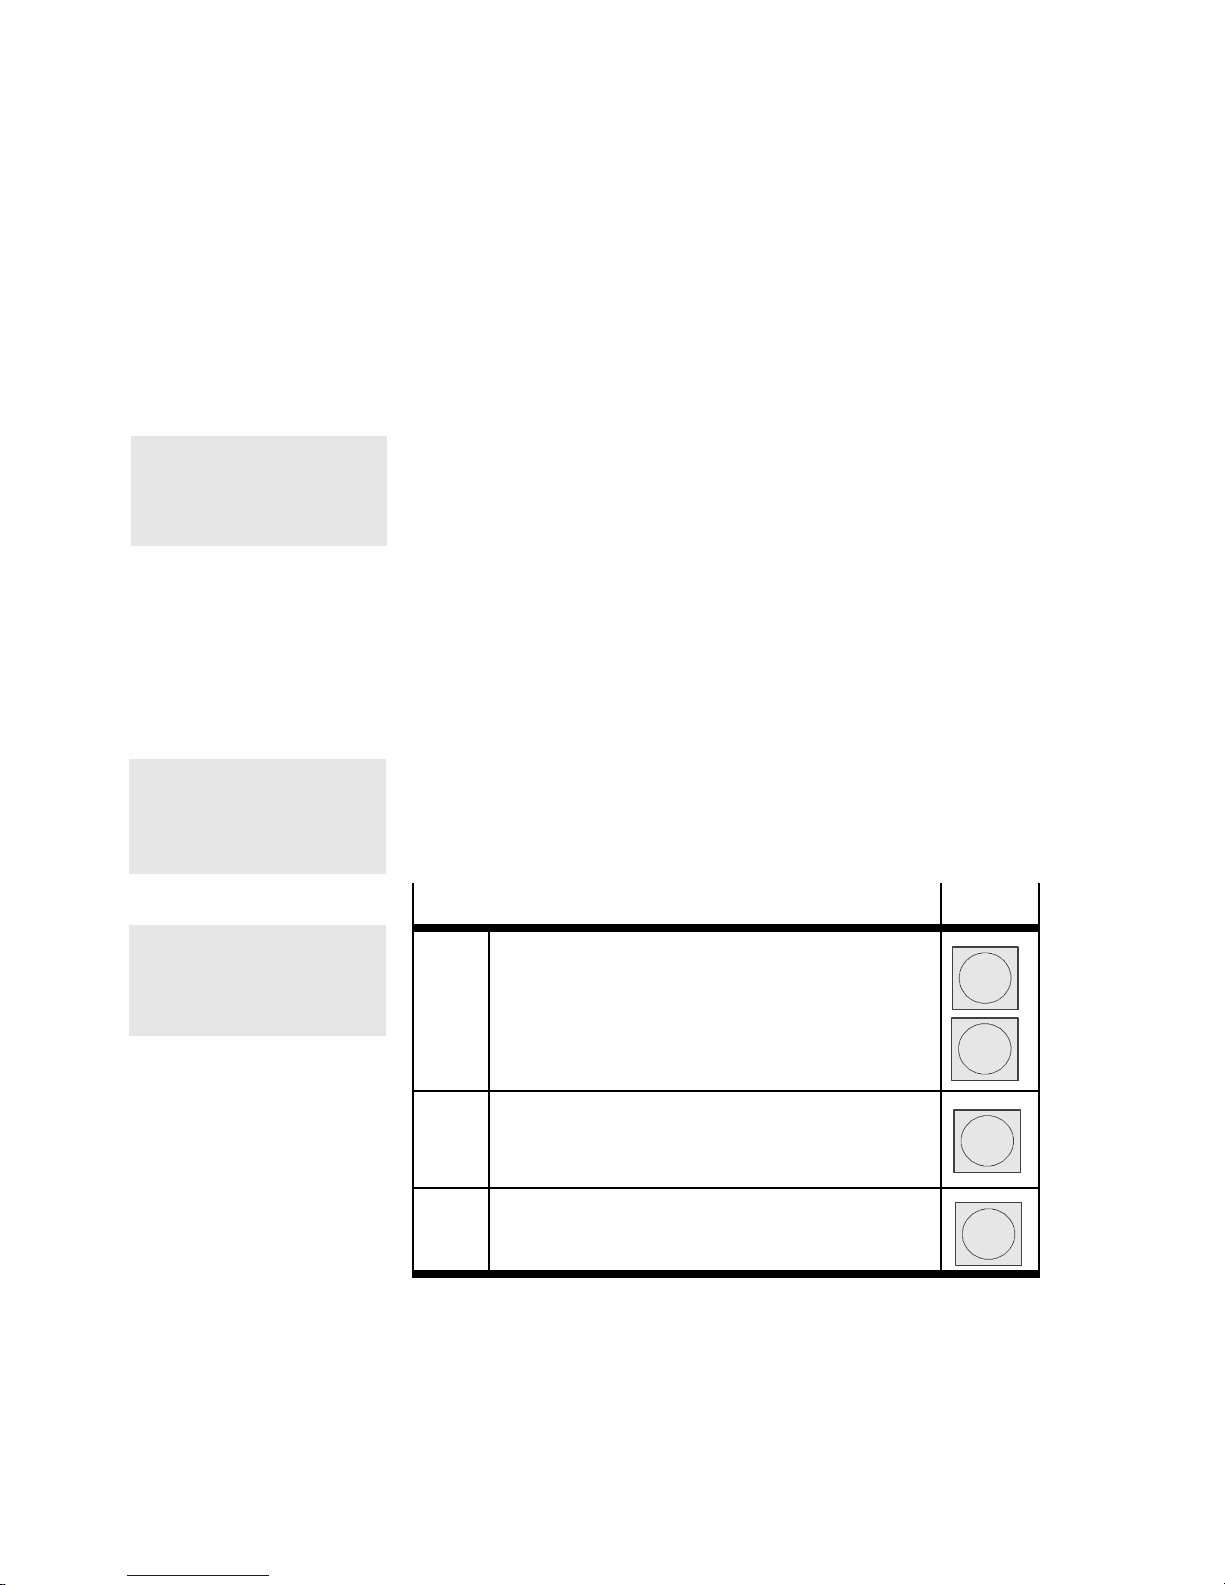
Function
<- -> With the arrow buttons on the control panel you
can select a menu item from the list. The current
selection is marked with an arrow (} Diagnostic). Select the menu item S in order to
display further menu items (HMI control...).
Button
v
V
4-6
ESC With <Menu> you can interrupt the current entry
and return in stages to the higher-order menu
level or status display.
OK With <Enter> you can confirm the current
selection or entry.
Tab. 4/2: Button function (menu selection)
Festo P.BE-MTR-DCI-IO-EN en 1209d
Menu
Enter
Page 65
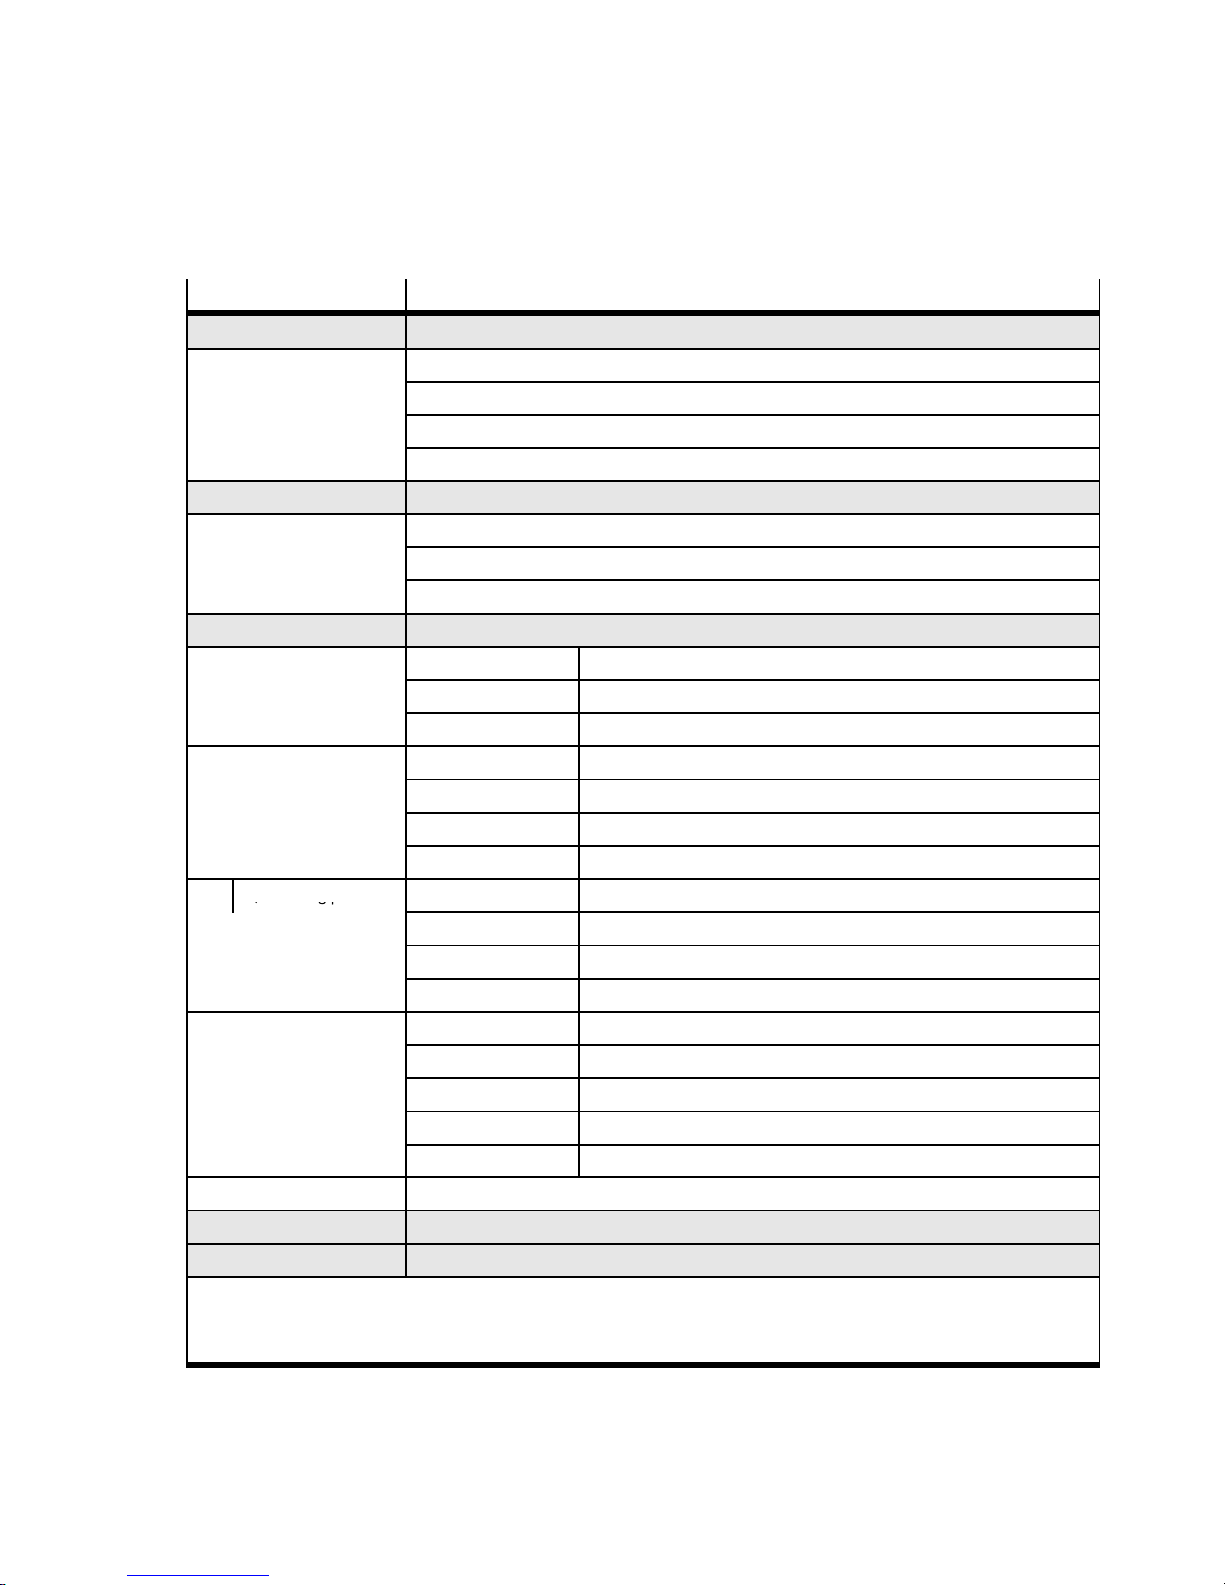
4. Control panel (MTR-DCI-...-H2IO)
}
g
p
Menu command Description
} Diagnostic Display the system data and the currently effective settings (see chapter 4.2.2)
} Pos set table Display the position set table
} Axis param Display axis parameters and data
} System param Display system parameters and system data
} SW information Display the operating system version (firmware)
1) 2)
1) 2)
1)
Homing and positioning run for testing the position sets (see chapter 4.2.4)
Select the drive, parametrizing, programming the po sition sets ... (see chapter 4.2.3)
} Rotation drive Rotation axis with stop
} User config Any linear drive
3)
} Abs.min.pos
} Abs.max.pos
} Save... Save p arameters in EEPROM
} Velocity v_sw Po sitioning speed for searching for the reference point
} Velocity v_s0 Positioning speed for moving to th e axis z ero point
} Save... Save p arameters in EEPROM
} Pos set mode Set status: absolute or relative positioning
} Position
} Velocity Positioning speed of the position set
} Save... Save p arameters in EEPROM
Preset the device control via the control panel (see chapter 4.2.5)
3)
Offset of axis zero point
3)
Stroke limitation: Software end position, negative
3)
Stroke limitation: Software end position, positive
Target position of the position set
} Positioning
} Move posit set Start po sitioning run “Position set”
} Demo posit tab Start positioning run “Position set table”
} Homing Start homing run
} Settings
} Axis type } Type DMES Positioning axis DMES
} Axis param } Zero point
} Homing param } Homing method Select referencing (homing) method (stop, software limit switch...)
} Position set } Position no. Number of the position set (0...14)
} Password Set up a local password with 3 figures for the control panel (see chapter 4.2.3).
} HMI control
} LCD adjustment Rotate the display in steps of 90°
1)
If necessary password protection
2)
Control interface must be deactivated, see [HMI control] :HMI = on
3)
Teach mode
Tab. 4/3: Menu commands (overview)
Festo P.BE-MTR-DCI-IO-EN en 1209d
4-7
Page 66
4. Control panel (MTR-DCI-...-H2IO)
For selecting the menu commands [Positioning] and [Settings]
you will require the setting “HMI: on”. Only then is the
MTR-DCI ready to process user entries on the control panel.
When selecting the menu commands, you will be requested
to modify the HMI setting.
You can also modify the setting directly in the main menu
with the menu command [HMI control].
4.2.2 Menu [Diagnostic]
Inordertodisplaythesystemdataandthecurrentlyeffective
settings:
} Diagnostic
} Pos.set table
Axis param
System param
SW information
1. Select [Diagnostic] in the main menu with the arrow
buttons and press the <Enter> button.
2. Select one of the following menu commands:
– Position set table [Pos. set table]
– Axis parameter [Axis param]
– System parameter [System param]
– Version of firmware of the MTR-DCI [SW information]
Function
<- -> You can “scroll through” the
diagnostic data with the arrow
buttons.
ESC With <Menu> you can return to the
higher-order menu level.
Button
v
Menu
V
4-8
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 67
4. Control panel (MTR-DCI-...-H2IO)
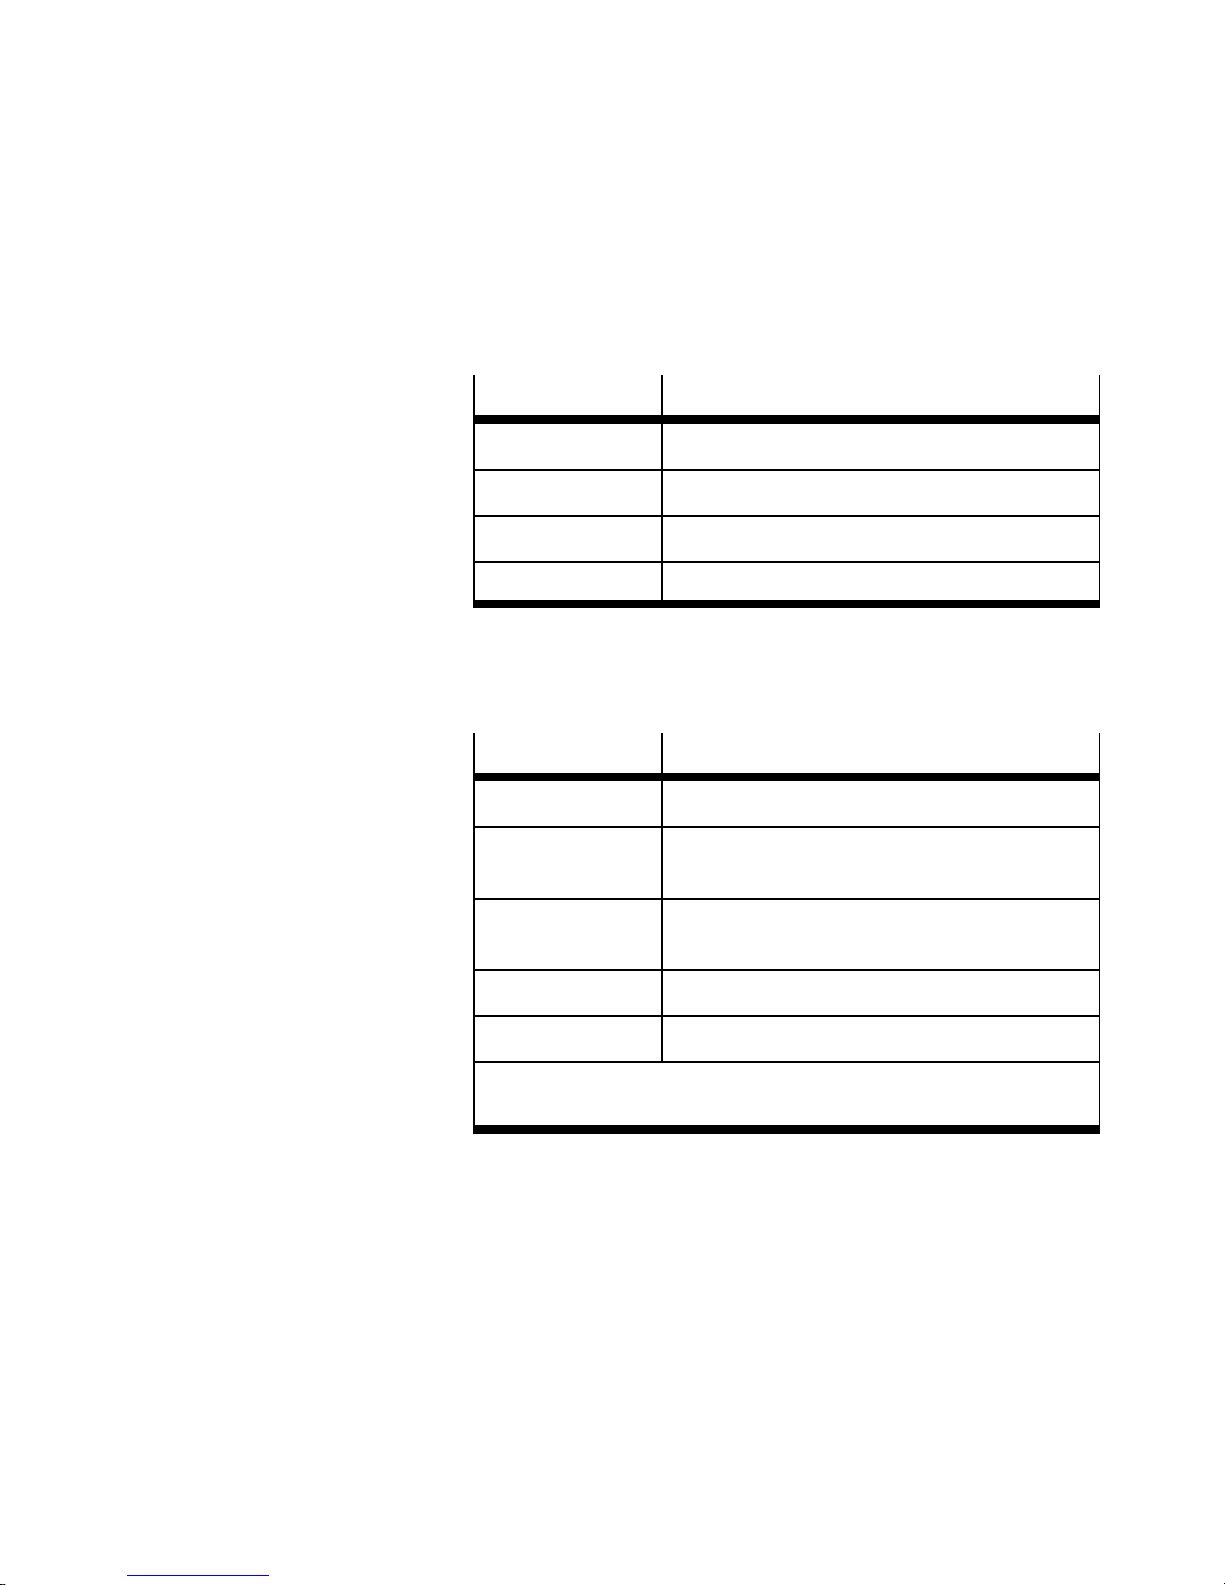
[Pos. set table] Menu command for displaying the following entries in the
position set table:
[Pos. set table]
Nr Number of the position set (0...14)
a/r absolute (a) or relative (r) positioning
Pos Target position
Vel Positioning speed
Description
[Axis param] Menu command for displaying the following axis parameters
and data:
[Axis param]
vmax Maximum positioning speed
xmin Stroke limitation: Software end position,
xmax Stroke limitation: Software end position,
1)
Description
negative
positive
Festo P.BE-MTR-DCI-IO-EN en 1209d
x0 Offset axis zero point
2)
feed
1)
Measuring unit depends on measuring system set
2)
Not for axis type “Rotation drive”
Feed constant
4-9
Page 68
4. Control panel (MTR-DCI-...-H2IO)
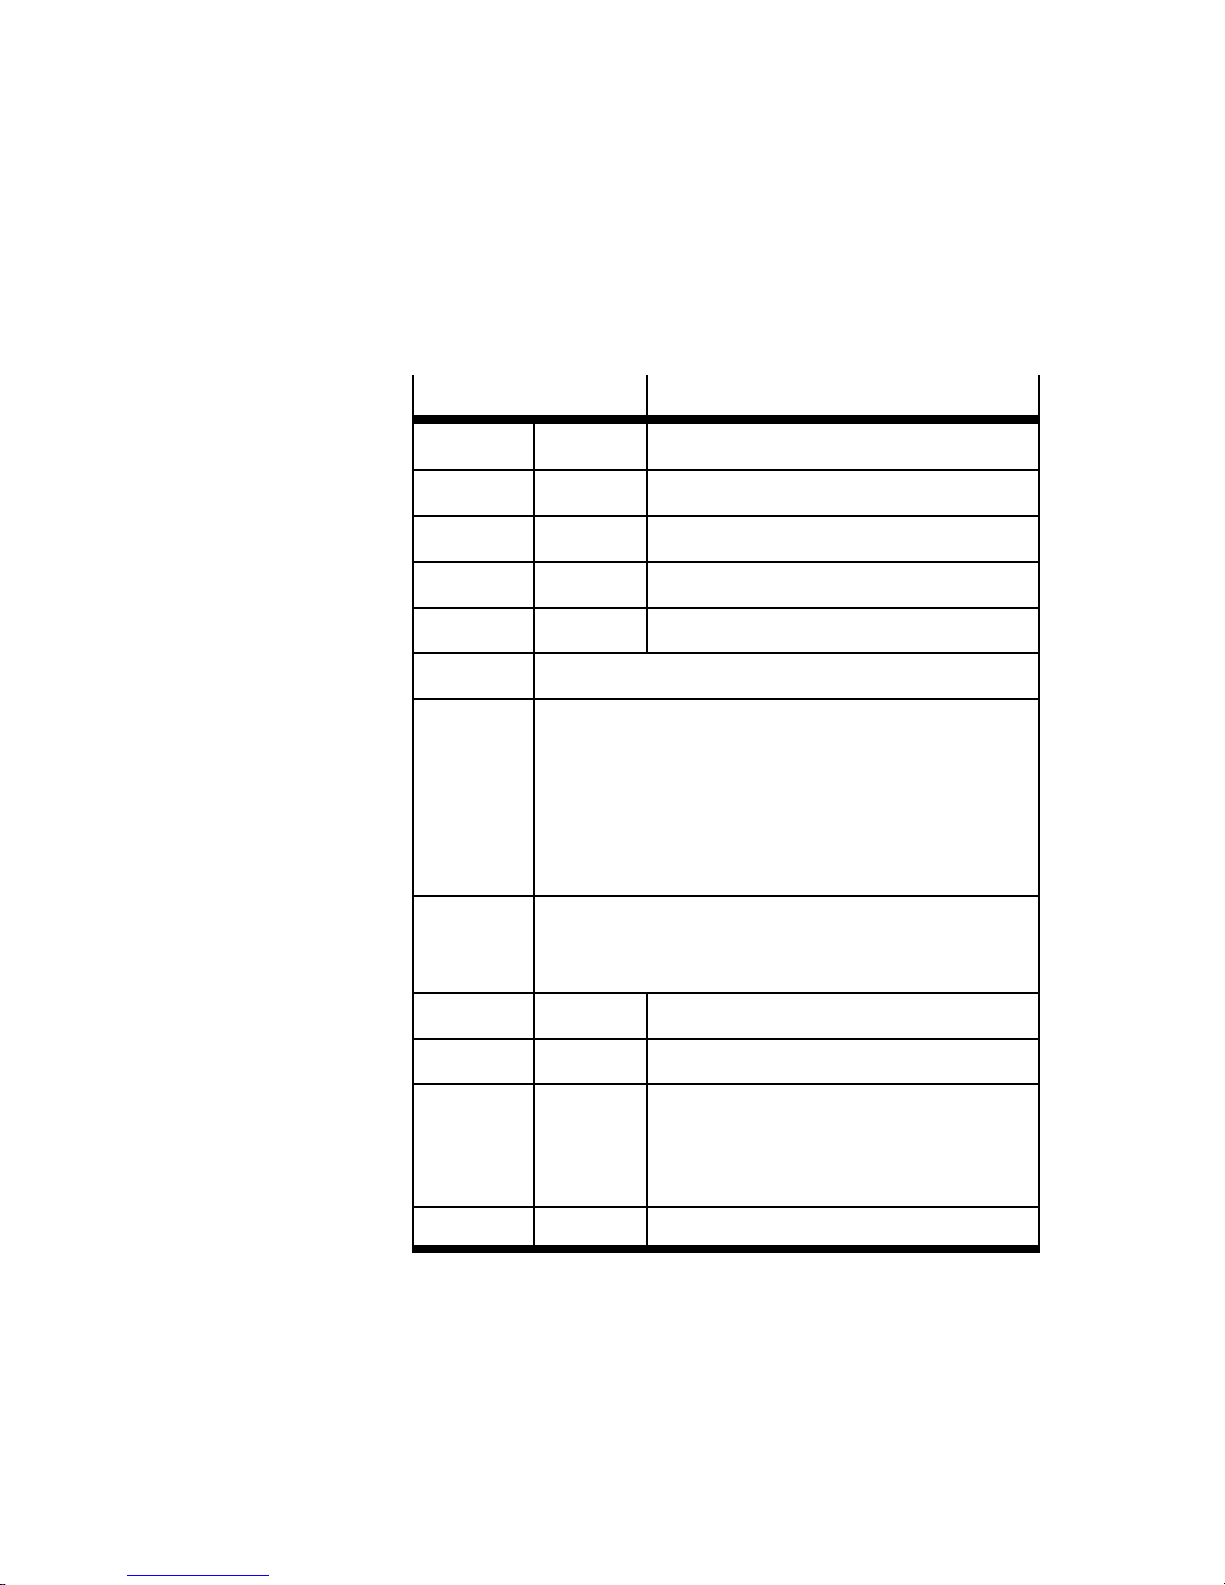
[System param] Menu command for displaying the foll o w i ng system para-
meters and data:
[System param]
Vpower [V] Supply voltage
Vdd [V] Voltage of display
Imax [A] Maximum current
Iact [A] Current current
Temp [°C] Operating temperature
Cycle Number of positioning movements
In signal Hexadecimal representation of the inputs
Bit 0: I0
Bit 1: I1
Bit 2: I2
Bit 3: I3
Bit 4: START
Bit 5: ENABLE
Out signal Hexadecimal representation of the outputs
Bit 0: READY
Bit 1: MOTION COMPLETE
Description
4-10
Ref. switch on/off Signal at reference switch input
Mode e.g. mm Measuring system
Hom.meth. –bl.pos
–bl.neg
–sw.pos
–sw.neg
Gear e.g. 6.75 Gear ratio of the MTR-DCI
Fixed stop in positive direction
Fixed stop in negative direction
Reference switch in positive direction
Reference switch in negative direction
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 69
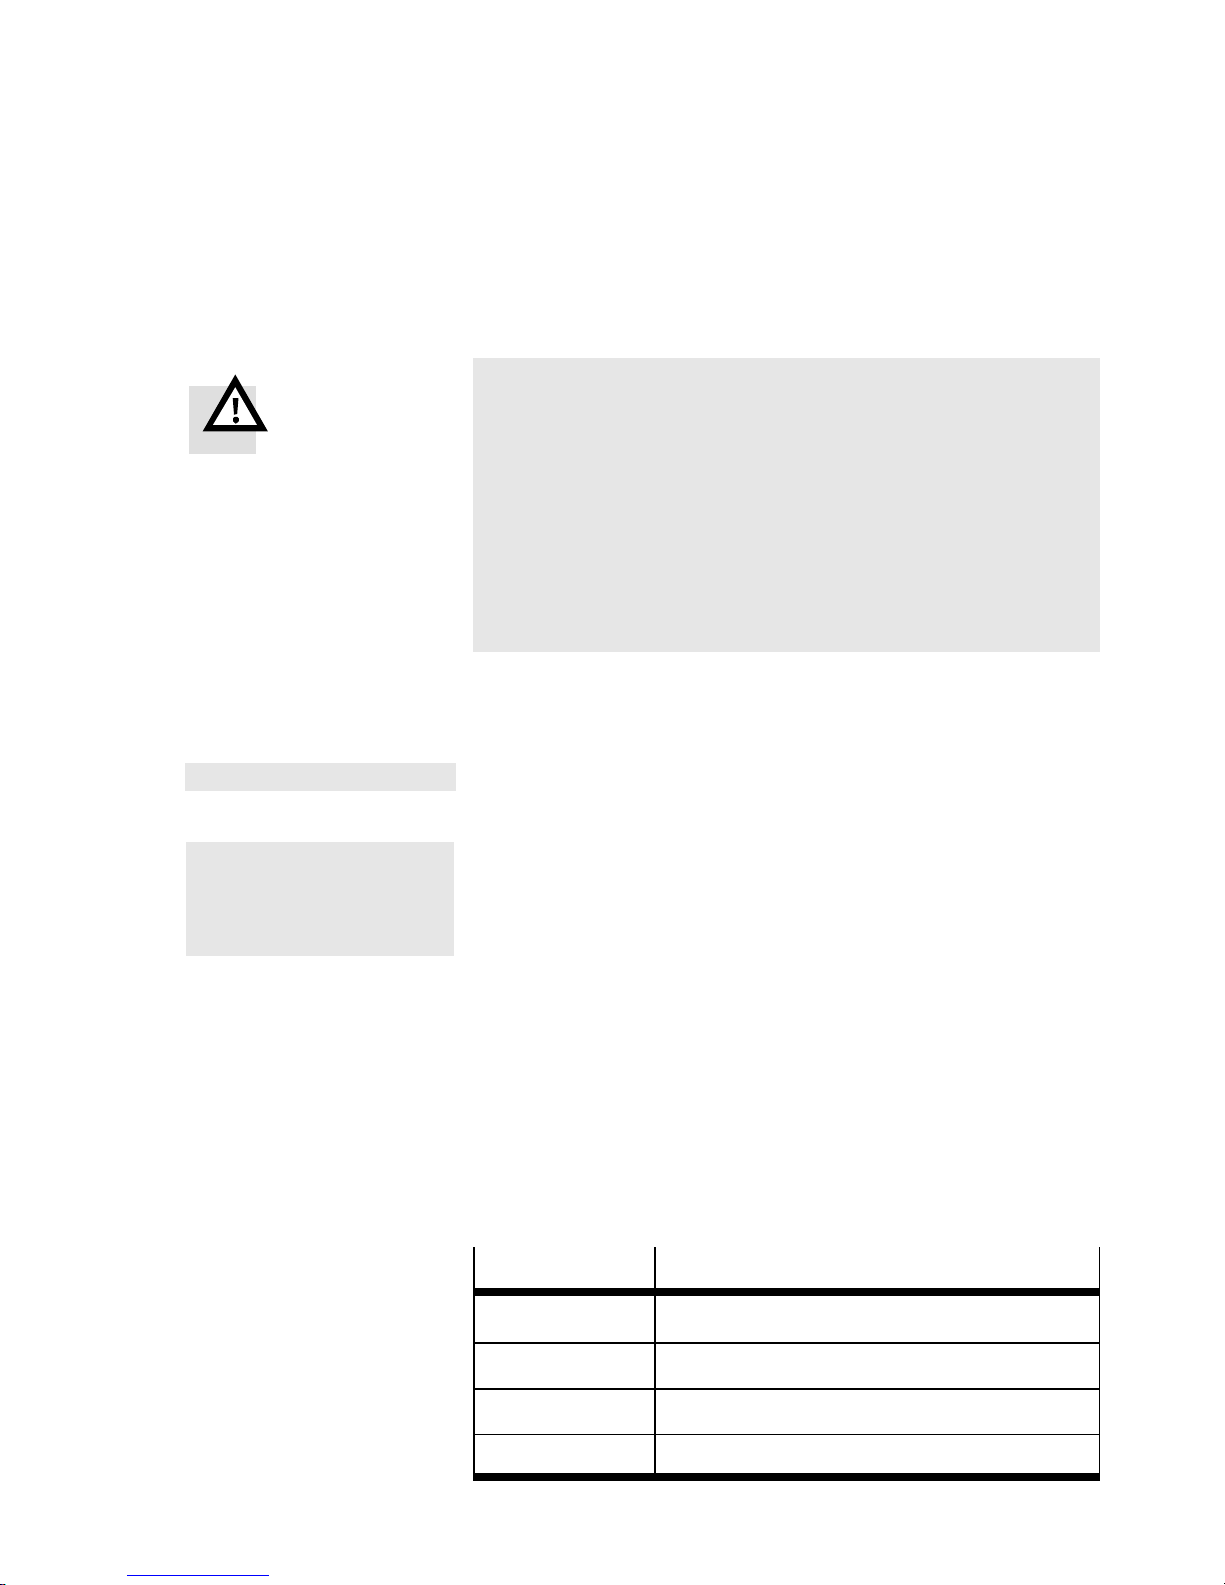
4. Control panel (MTR-DCI-...-H2IO)
4.2.3 Menu [Settings]
Warning
Damage to or impairment of the mechanical components
With all teach procedures the motor turns or the connected
axis starts to move.
•
Make sure that:
– nobody can place his/her hand in the positioning
– there are no objects in the positioning range.
range
Parametrizing the axis system and programming the position
sets:
} Settings
1. Select [Settings] in the main menu with the arrow buttons
and press the <Enter> button.
} Axis type
Axis param
Homing param
Position set
Password
2. Select:
– the axis type [Axis type]
– the axis parameters [Axis param]
– the reference run parameters [Homing param]
– the position set table [Position set]
– the password setting [Password].
[Axis type] Design of the axis driven by the MTR-DCI (parameters see
chapter 5.2.1)
[Axis type]
Description
Festo P.BE-MTR-DCI-IO-EN en 1209d
[Type DMES-...] Festo positioning axis
[Rotation drive] Specific rotation axis
[User config] Specific linear axis
[Save...] Save parameter in EEPROM
4-11
Page 70
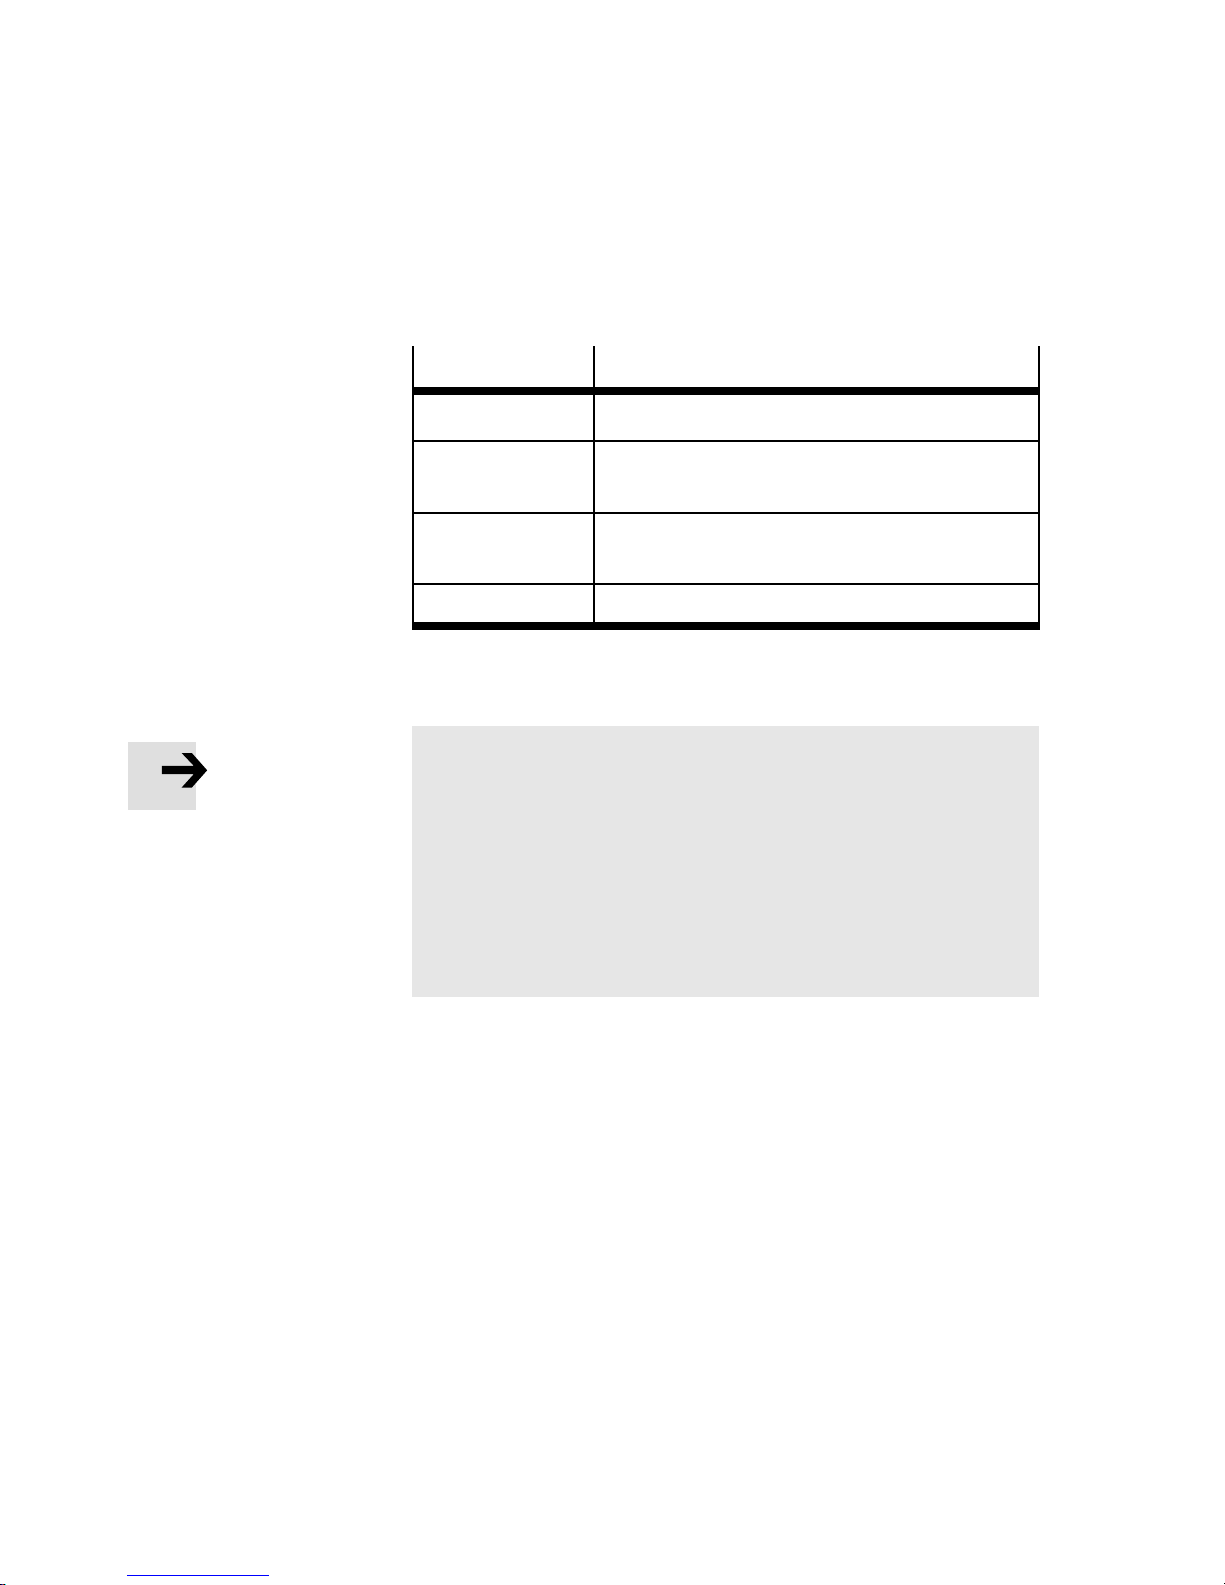
4. Control panel (MTR-DCI-...-H2IO)
[Axis param] Teach mode for setting the axis parameters
[Axis param]
[Zero point] Offset of axis zero point
[Abs.min.pos] Stroke limitation: Software limit switch,
[Abs.max.pos] Stroke limitation: Software limit switch,
[Save...] Save parameter in EEPROM
Description
negative
positive
Note
The set parameters become effective immediately after
confirmation with OK <Enter>. The settings are saved permanently in EEPROM with the menu command [Save...]:
•
Save the parameter settings with the menu command
[Save]. Only then will the settings be retained even if the
power supply is switched off or if there is a power
failure.
4-12
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 71
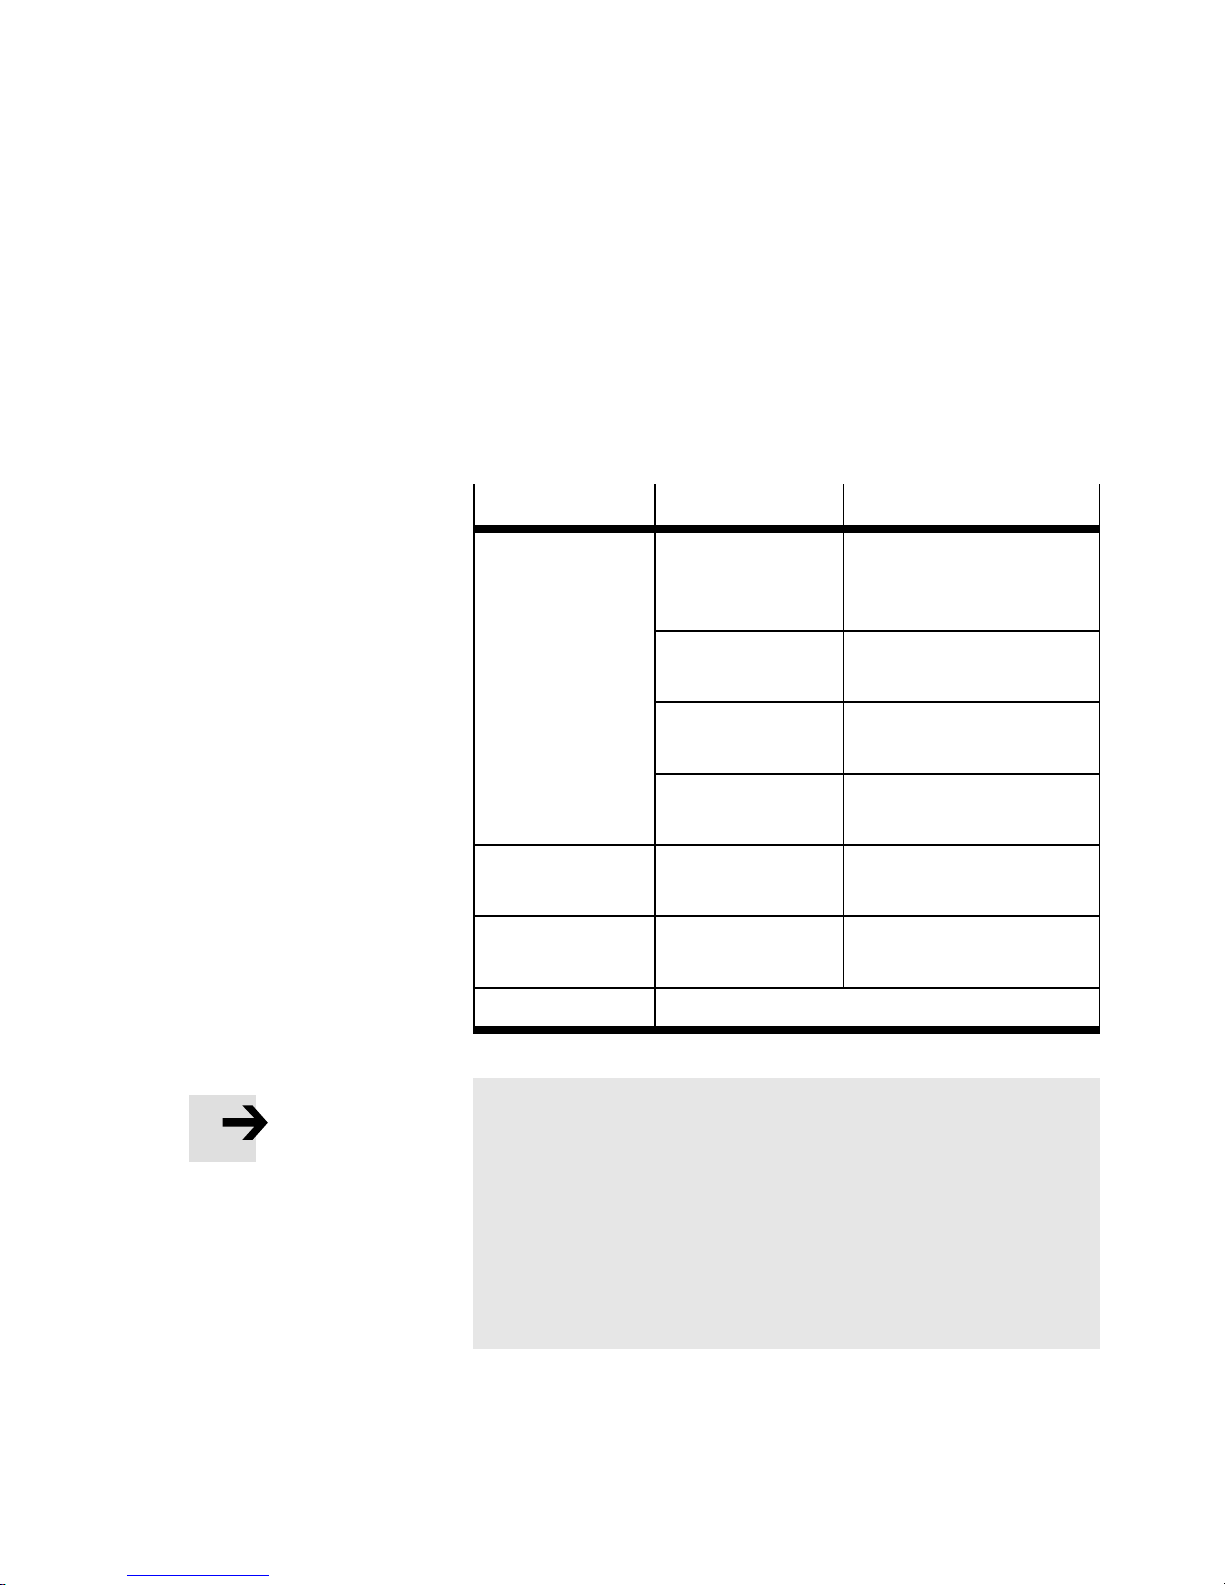
4. Control panel (MTR-DCI-...-H2IO)
[Homing param] Setting the reference travel method and the speed during
reference travel.
The maximum speed during homing is limited to half the
maximum positioning speed v_max (v_max see [Diagnostic]
[Axis param] ).
[Hom. param]
[Homing method] sw.neg
[Velocity v_sw] v_sw Speed for searching for
[Velocity v_s0] v_s0 Speed for moving to the
[Save...] Save parameter in EEPROM.
Param. Description
Homing to reference
(switch negative)
sw.pos
(switch positive)
bl.neg
(block negative)
bl.pos
(block positive)
switch, negative
= factory setting
Homing to reference
switch, positive
Homing to fixed stop,
negative
Homing to
fixed stop, positive
the reference point
axis zero point
Festo P.BE-MTR-DCI-IO-EN en 1209d
Note
The set parameters become effective immediately after
confirmation with OK <Enter>. The settings are saved permanently in EEPROM with the menu command [Save...]:
•
Save the parameter settings with the menu command
[Save]. Only then will the settings be retained even if the
power supply is switched off or if there is a power
failure.
4-13
Page 72
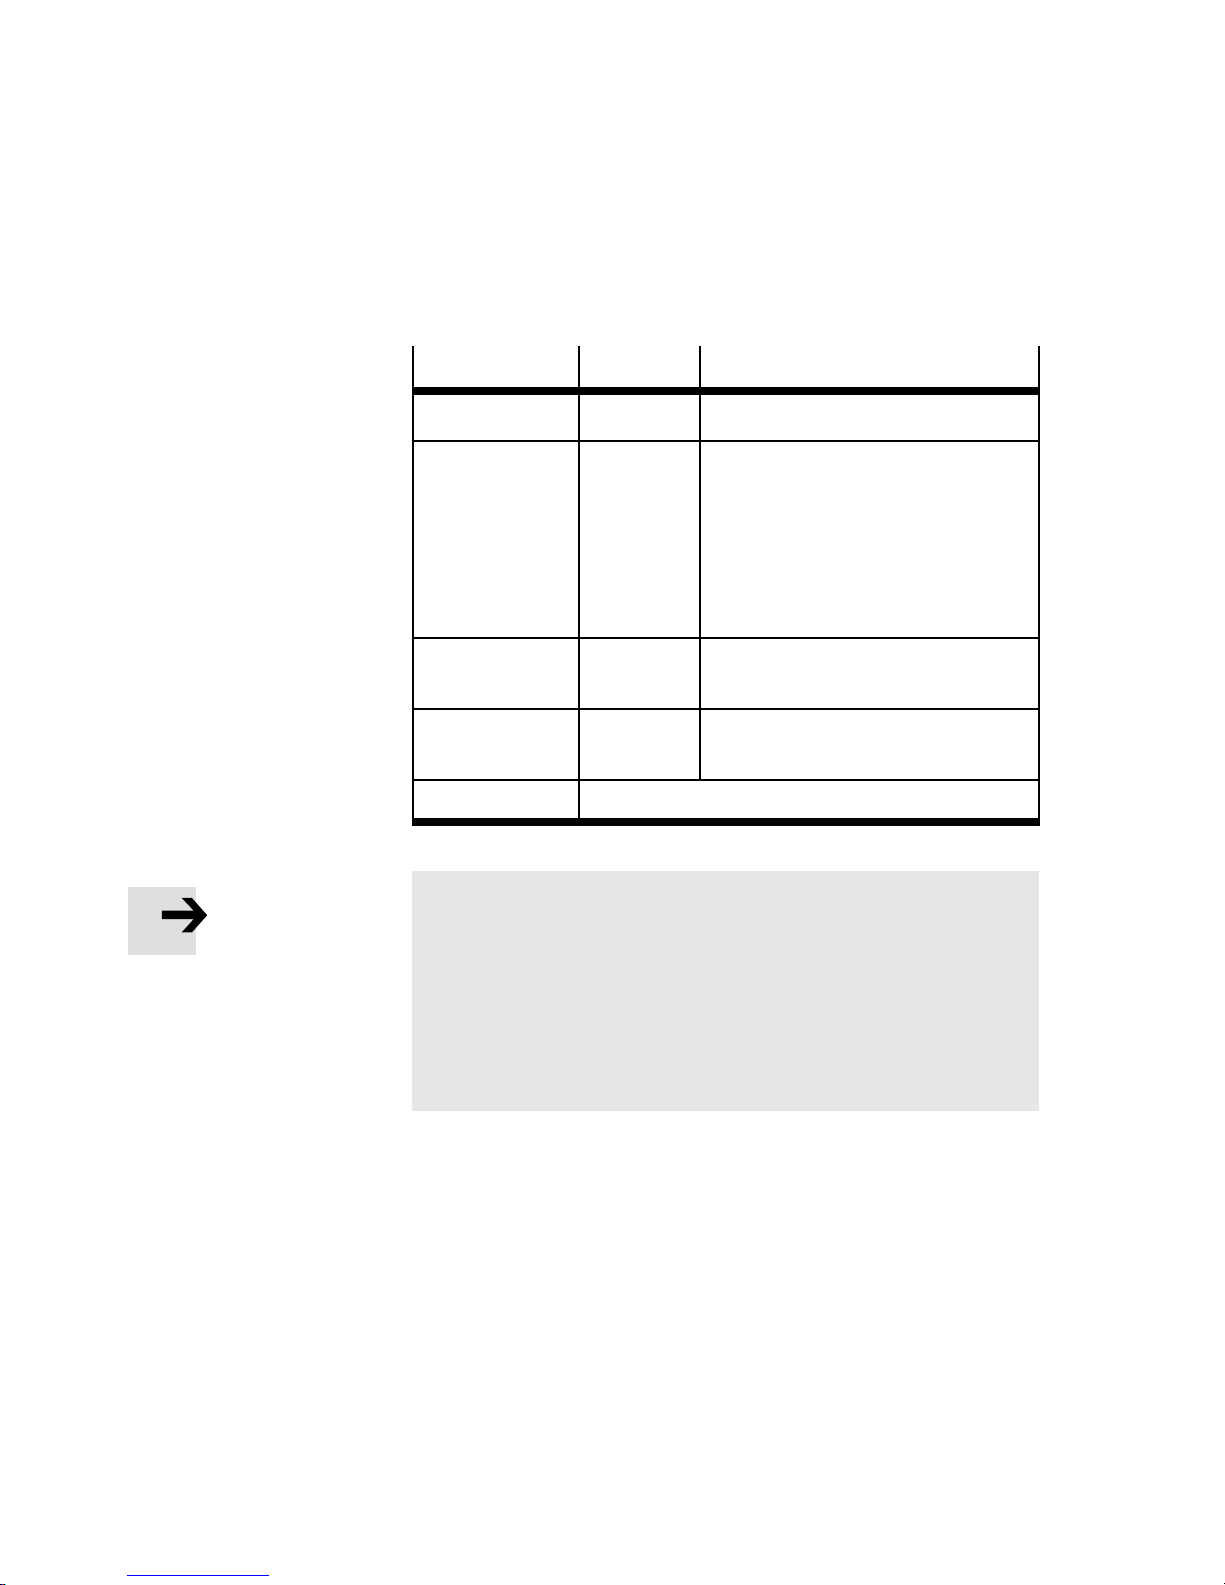
4. Control panel (MTR-DCI-...-H2IO)
[Position set] Teach mode for programming the position set table.
[Position set]
[Position nr] Nr Number of the position set [0...14]
[Pos set mode] [absolute/
[Position] x
[Velocity] v Positioning speed in the selected
[Save...] Save parameter in EEPROM
Param. Description
Positioning mode
relative]
t
absolute = absolute position
specification, related to the project
zero point
relative = relative position
specification, related to the current
position
Target position in the selected
measuring system e.g. [mm]
measuring system e.g. [mm/s]
Note
The set parameters become effective immediately after
confirmation with OK <Enter>. The settings are saved permanently in EEPROM with the menu command [Save...]:
4-14
•
Save the parameter settings with [Save]. Only then will
the settings be retained even if the power supply is
switched off or if there is a power failure.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 73
4. Control panel (MTR-DCI-...-H2IO)
Set up a password
In order to prevent unauthorized or unintentional overwriting
or modification of parameters in the device, access via the
control panel can be protected by a (local) password. No
password is specified at the factory (presetting 000).
[Password] Select [Settings] [Password] in the menu:
New Password:
[?xx] =
ESC <menu>
EDIT <--> OK <Enter>
Enter password:
[?xx] =
ESC <menu>
EDIT <--> OK <Enter>
Enter a password with 3 figures. The current entry position is
marked with a question mark.
1. Use the arrow buttons to select a figure 0...9.
2. Confirm your entry with <Enter>. The next entry position
will be displayed.
3. After entering the third figure, save your setting with
SAVE <Enter>.
Enter password
As soon as a password is active, it will be scanned automatically when the menu commands [Positioning], [Settings] or
[HMI control] are accessed. When the correct password is
entered, all parametrizing and control functions of the control
panel are enabled until the power supply is switched off.
The current entry position is marked with a question mark.
Festo P.BE-MTR-DCI-IO-EN en 1209d
1. Use the arrow buttons to select a figure 0...9.
2. Confirm your entry with <Enter>. The next entry position
will be displayed.
3. Repeat the entry for the further entry positions.
When the third figure has been entered, access via the
control panel is enabled.
4-15
Page 74
4. Control panel (MTR-DCI-...-H2IO)
Modify/deactivate password
[Password] Select [Settings] [Password] in the menu:
Enter password:
[?xx] =
ESC <menu>
EDIT <--> OK <Enter>
New Password:
[?xx] =
ESC <menu>
EDIT <--> OK <Enter>
Enter the existing password with 3 figures. The current entry
position is marked with a question mark.
1. Use the arrow buttons to select a figure 0...9.
2. Confirm your entry with OK <Enter>. The next entry
position will be displayed.
3. Repeat the entry for the further entry positions.
4. Enter the new password with 3 figures. If you wish to
deactivate the password, enter “000”.
5. After entering the third figure, save your setting with
SAVE <Enter>.
•
KeepthepasswordfortheMTR-DCIinasafeplace,e.g.
with the internal documentation for your system.
If the active password in the MTR-DCI should be lost in spite
of care being taken:
you can delete the password by entering a master password.
In this case please contact your Festo Service partner.
4-16
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 75
4. Control panel (MTR-DCI-...-H2IO)
4.2.4 Menu [Positioning]
Start reference run or positioning run for testing the position
sets.
Warning
Damage to or impairment of the mechanical components
With all positioning procedures the motor turns or the
connected axis starts to move.
•
Make sure that:
– nobody can place his/her hand in the positioning
range
– there are no objects in the positioning range.
Note
•
Before starting the reference run, make sure that:
– the positioning system is set up completely, wired
and supplied with power,
– the parametrizing is completed.
•
Do not start a positioning run until the reference system
has been defined by means of a reference run.
Note
Please note that position sets with speed v = 0 or invalid
target positions (-> Fault TARGET POSITION OUT OF LIMIT)
cannot be processed.
Festo P.BE-MTR-DCI-IO-EN en 1209d
4-17
Page 76
4. Control panel (MTR-DCI-...-H2IO)
Carry out homing
} Positioning
1. Select [Positioning] in the main menu with the arrow
buttons and press the <Enter> button.
Move posit set
Demo posit tab
} Homing
2. Select the menu command:
–[Homing]
[Positioning] Description Note
[Homing] Homing for determining the
mechanical reference system
...
Warning Motor moves
3. Make sure that nobody can place his/her hand in the
positioning range of the moveable mass and that there
First set the parameter in the menu [Settings]
[Homing parameter].
Factory setting: Homing to reference switch in
negative direction.
are no objects in its path. Start homing run with START
ESC <menu>
START <Enter>
HOMING
V_0= 20 mm/s
v_sw = 10 mm/s
<Enter>.
The following information is displayed:
– the search speed v_sw
EMERG.STOP<Menu>
4-18
– the positioning speed to the axis zero point v_0.
Function
EMERG.
STOP
With <Menu> you can interrupt the positioning
procedure (> Error mode EMERG.STOP;
confirm with <Enter>, then automatic return to
the status display).
Festo P.BE-MTR-DCI-IO-EN en 1209d
Menu
Page 77
4. Control panel (MTR-DCI-...-H2IO)
Process position sets
} Positioning
1. Select [Positioning] in the main menu with the arrow
buttons and press the <Enter> button.
} Move posit set
Demo posit tab
Homing
2. Select the menu command:
– Positioning run “Position set” [Move posit set] – or
– Positioning run “Position set table” [Demo posit tab]
[Positioning]
[Move posit set] Positioning run for testing a certain
[Demo posit tab] Positioning run (continuous loop) for
...
Warning Motor moves
Description Note
position set in the position set table.
testing all position sets (0...14) in the
position set table.
With positioning run [Demo posit tab] all position sets 0...14
in the position set table will be processed one after the other.
If the position set table contains a position set with speed v =
ESC <menu>
START <Enter>
0, this position set and all the fol l o wing sets will not be processed; positioning run will be continued with position set 0.
Parametrizing and referencing must
be completed.
Parametrizing and referencing must
be completed.
There must be at least two position
sets in the memory.
Move posit set
Pos 1
= 100.00 mm
X
t
v = 20 mm/s
= 90.00 mm
X
a
EMERG.STOP<Menu>
Festo P.BE-MTR-DCI-IO-EN en 1209d
3. Make sure that nobody can place his/her hand in the
positioning range of the moveable mass and that no objects lie in its path. Start the positioning procedure with
START <Enter>.
During the positioning run the following information is
displayed:
– the active position set Pos...
– the target position x
t
– the positioning speed v
– the current position x
a.
4-19
Page 78
4. Control panel (MTR-DCI-...-H2IO)
Function
EMERG.
STOP
DEMO
STOP
With <Menu> you can interrupt the positioning
procedure (> Error mode EMERG.STOP; confirm with <Enter>, then automatic return to
the status display).
With <Enter> you can interrupt the positioning
run “Pos set table” [Demo pos tab].
The current positioning set will be processed
before the axis stops. A new start will be
made with position set 0.
4.2.5 Menu command [HMI control]
For selecting the menu commands [Positioning] and [Settings]
you will require the setting “HMI: on”. Only then is the
MTR-DCI ready to process user entries on the control panel.
When selecting the menu commands, you will be requested
to modify the HMI setting.
[HMI control] You can also modify the setting directly with the menu
command [HMI control].
Menu
Enter
4-20
1)
HMI
on The device control is carried out manually via the control
off The device control is carried out via the control interface
1)
Human Machine Interface
Device control
panel. The control interface of the MTR-DCI is deactivated
and the control enable is set. The ac tual status of the
ENABLE input then has no effect.
of the MTR-DCI.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 79
Commissioning
Chapter 5
Commissioning
Festo P.BE-MTR-DCI-IO-EN en 1209d
5-1
Page 80
5. Commissioning
Contents
5. Commissioning 5-1................................................
5.1 Procedure for commissioning 5-3.....................................
5.2 Commissioning with the control panel (only MTR-DCI-...-H2) 5-6............
5.2.1 Selecting the axis type 5-7...................................
5.2.2 Setting the homing parameter 5-9.............................
5.2.3 Teach the axis zero point and the software end positions 5-13.......
5.2.4 Positioning with positio n sets 5-15..............................
5.2.5 Teach position sets 5-16......................................
5.2.6 Test run 5-17...............................................
5.3 Commissioning with FCT 5-19.........................................
5.3.1 Installing the FCT 5-19........................................
5.3.2 Procedure for commissioning with the Festo Configuration Tool 5-20..
5.4 Communication with the higher-order controller 5-22......................
5.4.1 I/O function check 5-22.......................................
5.4.2 Description of the I/Os 5-23...................................
5.4.3 Function description (pulse-time diagram) 5-26...................
5-2
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 81
5. Commissioning
5.1 Procedure for commissioning
Warning
Danger of injury.
Electric axes can move suddenly with high force and at
high speed. Collisions can lead to serious injury to human
beings and damage to components.
•
Make sure that nobody can gain access to the operating
range of the axis or of other connected actuators and
that no objects lie in the path of the axes while the system is still connected to a power supply (voltage).
Note
In the following cases it is not permitted to access the
MTR-DCI with the FCT writing (e.g. downloading parameters) or controlling (e.g. with “Move manually” or when
starting homing run):
– When the MTR-DCI is currently performing a positioning
movement or when a movement is started during access
(e.g. via the control interface or via the control panel).
– When parametrizing or operation is carried out with the
control panel of the MTR-DCI.
Pleasenotethefollowing:
•
The device connection in the FCT must not be activated
when the control panel is being used for control (“HMI
control = on”).
•
Control with the control panel (“HMI control = on”) must
not be activated when the device connection in the FCT
is activated.
•
Control by the FCT must not be activated while the drive
is in motion or when control is being carried out via I/Os.
Festo P.BE-MTR-DCI-IO-EN en 1209d
5-3
Page 82
5. Commissioning
Before commissioning
•
Before commissioning the servo drive make sure that:
– the work space is of sufficient size for operation with a
work load,
– the work load does not collide with the motor or the
gear of the axis when the axis moves into the end
position.
•
Pleaseobservethenotesintheoperatinginstructionsfor
the positioning drive.
Switch-on reaction
First commissioning Relative positioning movements can be carried out as soon as
the device is switched on, e.g. in order to position the axis in
the permitted positioning range. If an absolute positioning
process is started, the following error will be displayed: LAST
ACTUAL POSITION IS NOT SAVED! PLEASE ENFORCE HOMING
RUN. Absolute positioning movements can only be carried
out after a homing run.
•
Execute a homing run every time thedeviceisswitched
on. For the homing method refer to chapter 1.5.3.
5-4
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 83
5. Commissioning
Switching on
Note
Note that the tolerance for the supply voltage must be
observed. The tolerance must also be observed directly
at the operating voltage connection of the MTR-DCI
(see chapter 3.3).
Note
•
Make sure that the axis is within the permitted positioning range when it is switched on. Instructions on this can
be found in chapter 1.5.1.
•
When the power supply is switched off, wait for approx.
5 seconds before switching the device on again.
•
Switch on the power supply for the MTR-DCI.
When the power supply is switched on, the MTR-DCI
automatically carries out an internal check.
•
Carry out parametrizing and commissioning with the
control panel or the FCT, as described in the following
chapters or in the FCT/PlugIn help.
•
In order to complete commissioning note the instructions
for operation in the FCT/PlugIn help and in chapter 6.1.
Festo P.BE-MTR-DCI-IO-EN en 1209d
5-5
Page 84
5. Commissioning
5.2 Commissioning with the control panel (only MTR-DCI-...-H2)
Informationonthebuttonfunctionsandonthemenucomposition of the control panel can be found in chapter 4.
Device control
Diagnostic
positioning
Settings
} HMI control
LCD adjustment
In order that the control panel can control the connected
MTR-DCI, the control interface of the MTR-DCI must be
deactivated and controller enable must be set [HMI = on].
The actual status of the ENABLE input then has no effect.
Instructions on parametrizing and commissioning
Information on the current parametrizing of the motor unit
can be found in the menu [Diagnostic] on the control panel.
Carry out the following steps in order to commission the
MTR-DCI the first time with the control panel: Note the
detailed description in the chapters specified.
Commissioning (overview)
1. Select the axis type and, if necessary, adapt the
parametrizing to suit your axis.
2. Set the following parameters for reference travel:
– Homing method
– Search speed to reference point
– Positioning speed to axis zero point
Chapter
5.2.1
5.2.2
5-6
3. Carry out homing run. 5.2.2
4. Teach the following axis parameters for defining the
axis zero point and the working area:
– Offset of the axis zero point to the reference point
– Positive and negative software end positions.
Festo P.BE-MTR-DCI-IO-EN en 1209d
5.2.3
Page 85
5. Commissioning
Commissioning (overview) Chapter
5. Enter several position sets (target position,
positioning mode and positioning speed).
6. Carry out a test run to check the positioning reaction
of the axis, as well as the basis coordinates and the
working area.
7. If necessary, optimize the settings for position sets as
well as for the basis c oordinates and the working area.
8. Check the function of the control interface of the
MTR-DCI (function test).
9. Before completing commissioning, note the
instructions on operation.
5.2.4
5.4.1
6.1
Tab. 5/1: Commissioning (overview)
In order to restore the default settings, the EEPROM can be
deleted, if required, with the CI command 20F1 (Data memory
control) directly via the serial interface (see chapter B.1.2).
5.2.1 Selecting the axis type
} Settings
Axis type
Type DMES...
Rotation drive
User config
1. Select the axis type which matches your positioning
system.
– Festo positioning axis [Type DMES]
– Rotation axis [Rotation drive]
– Linear axis [User config].
2. Depending on the entry requested, set axis-specific
parameters by means of the arrow buttons:
– feed constant (Feedcon) or
– measuring system (degree/revolutions).
3. Save the setting with SAVE <Enter>.
Festo P.BE-MTR-DCI-IO-EN en 1209d
5-7
Page 86
5. Commissioning
Axis type Feed constant
[mm/revolution]
Festo positioning
1) 2)
axis
DMES-18 1.5 Metric
Measuring
system
3)
DMES-25 2.5
DMES-40 4
DMES-63 6
Rotation axis — Degree or
revolutions
Linear axis
2)
According to the type
Metric
3)
plate or technical
specifications of the
axis
1)
Values defined at factory Z spindle pitch of the axis [mm]
2)
If an external gear is used, the gear factor can be set with
FCT.
3)
Pre-setting metric; inches can only be set with FCT
Tab. 5/2: Parametrizing the axis
5-8
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 87
5. Commissioning
5.2.2 Setting the homing parameter
Caution
Damage to components
The slide may only move against the fixed stop if the per-
mitted impact energy is not exceeded. The permitted value
can be found in the manual for your positioning axis.
Impact energy = 0.5 x mass x speed
For the protection of the mechanical components:
•
Reduce the speed at which homing run is carried out.
The speed can be specified at 0 % to 50 % of the rated
speed depending on the specific application.
2
•
If necessary, limit the motor current during homing run
with the FCT software. The motor current can be specified with 1 to 200 % of the rated motor current depending on the specific application (see FCT/PlugIn help
MTR-DCI).
Caution
If the homing method is changed, the axis zero point offset
is reset to zero. Any settings implemented for the software
end positions and the target positions in the positioning
record table are retained. Note that these values refer to
the previous axis zero point.
•
Always carry out a homing run after changing the referencing method.
•
Then teach the offset of the axis zero point.
If the axis zero point is modified:
•
Teach the software end positions and the target positions again.
Festo P.BE-MTR-DCI-IO-EN en 1209d
5-9
Page 88
5. Commissioning
Current limiting
The motor current can be specified with 1 to 200 % of the
rated motor current depending on the specific application
(see FCT/PlugIn help MTR-DCI).
Positioning axis DMES can carry out homing run with the factory-set current limitation (150 % of the rated motor current).
The current limitation need not be modified.
Current limitation
100 % Z
1 x rated motor current
150 % (default) Z
1.5 x rated motor current
200 % Z
2 x rated motor current
1)
Parameter specification in FCT: relative motor current in % of rated current, setting range 1...200.
2)
Due to maximum current limitation the value does not rise further.
1)
motor current
motor torque
motor current
motor torque
motor current
motor torque
A
mNm
A
mNm
A
mNm
32 42 52 62
0.73
30
1.1
46
1.46
62
2.0
110
3.0
171
3.8
220
5.0
300
7.5
460
2)
7.7
470
2)
Tab. 5/3: Current limitation
Note
Please note the following wh en adapting the current
limitation:
– By means of a current limitation, the maximum possible
speed of homing run will also be reduced. The set rated
speed will therefore, in some cases, no longer be
achieved.
6.19
700
9.29
1076
12.38
1450
5-10
– If the drive is arranged vertically, an increase in the
motor current may be necessary. If the motor current is
too low, homing run cannot be carried out.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 89
5. Commissioning
Set parameters
The reference point is defined by means of a reference switch
or fixed stop depending on the set homing method. If a homing run to a mechanical end position is not possible in the
application, an external sensor (reference switch) can be used
as reference signal (see also chapter 1.5.1).
Reference run parameters
32 42 52 62
(factory setting)
Homing method Reference switch, negative (near motor)
Velocities v_sw, v_s0 %
Rated speed of the motor rot/s
1)
% of the rated speed of the motor; max. 50 %
} Settings
Homing parameter
Homing method
Velocity v_
Velocity v_
Save
B+W
s0
•
Set the followi ng homing parameters one after the
other:
– the [Homing method]
– the search speed for ascertaining the reference point
1)
inc/s
inc/s
~41 %
27000
55
66000
~22 %
22400
50
10000050100000
~17%
16800
[Velocity v_sw]
– the positioning speed to the axis zero point
[Velocity v_s0].
~15%
16800
56,7
113400
Festo P.BE-MTR-DCI-IO-EN en 1209d
•
Accept each setting with OK <Enter>. The setting will then
become effective in the drive.
•
Save the parameter settings with the menu command
[Save]. Only then will the settings be retained even if the
power supply is switched off or if there is a power failure.
•
Finally, carry out a homing run, otherwise the previous
reference system of the MTR-DCI will remain unmodified.
5-11
Page 90
5. Commissioning
Start homing run
Note
When carrying out a homing run note that
– the drive must be in the permitted positioning range.
– the drive moves in the search direction according to the
selected homing method and, at the start, must be positioned in front of the fixed stop or reference switch.
1. If necessary, position the drive in the Teach mode so that,
at the start, it is positioned in front of the fixed stop or
reference switch in the search direction.
} Positioning
Demo posit tab
Move posit set
Homing
•
Select e.g. [Settings] [Position set] [Position] (see also
chapter 5.2.5).
•
Move the drive to the desired position manually with
the arrow buttons.
•
Interrupt the procedure with ESC <menu>, in order that
the position is not included in the position set table.
2. Select [Positioning] [Homing].
3. Start homing run with START <Enter>.
After successful reference travel the drive stands at the axis
zero point. During the initial commissioning procedure or
after changing the homing method, the offset of the axis zero
point = 0; after a homing run the drive then stands at the
reference point (= axis zero point).
5-12
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 91
5. Commissioning
Discontinue homing run
If necessary, homing run can be discontinued with the <Menu>
button (EMERG STOP). If homing run is interrupted, the display will show the fault message HOMING ERROR. If a correct
homing run has already been carried out, the previous reference point will retain its validity.
•
Quit the fault message with <Enter>.
•
Repeat homing run.
Fault during homing run
If a fault occurs during homing run:
•
quit the fault message with <Enter>
•
if necessary, check the function of the reference switch
•
check the settings of the parameters.
•
If necessary, position the drive in Teach mode so that at
the start it stands in the search direction in front of the
stop or reference switch.
•
Repeat homing run.
5.2.3 Teach the axis zero point and the software end positions
Prerequisites for teaching the axis zero point and the
software end positions:
Festo P.BE-MTR-DCI-IO-EN en 1209d
– Homing run was successful.
Note
When homing run to a stop, set the offset of the axis zero
point to ≠ 0. You will then prevent movement to the mechanical end positions during operation.
5-13
Page 92
5. Commissioning
Teach the axis zero point:
} Settings
Axis parameter
Zero point
Abs.min.pos
Abs.max.pos
Save
1. Select [Settings] [Axis parameter] [Zero point].
2. Move the drive to the desired axis zero point manually
with the arrow buttons.
3. Accept the position reached with OK <Enter>. The setting
will then become effective in the drive. The current position x
becomes the axis zero point (xa=0).
a
Note
If the axis zero point is modified:
Check existing settings of the software end positions and
of target positions in the position table. Note that these
values refer to the previous axis zero point.
•
Teach the software end positions and the target
positions again.
Teach the negative software end position and the positive
software end position:
1. Select [Settings] [Axis parameter] [Abs. min.pos] or
[Abs.max.pos].
2. Move the drive manually with the arrow buttons.
3. Accept the position reached with OK <Enter>. The setting
will then become effective in the drive.
4. Save the parameter settings with [Save]. Only then will the
settings be retained even if the power supply is switched
off or if there is a power failure.
5-14
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 93
5. Commissioning
5.2.4 Positioning with position sets
Warning
Damage to or impairment of the mechanical components.
With all positioning procedures the motor turns or the
connected axis starts to move.
•
Make sure that:
– nobody can place his/her hand in the positioning
range
– there are no objects in the positioning range.
The following conditions must be fulfilled:
– Homing run was successful.
– The axis zero point and the software end positions are set
correctly.
Note
Please note that position sets with speed v = 0 or invalid
target positions (-> Fault TARGET POSITION OUT OF LIMIT)
cannot be carried out.
•
After successful homing run, teach several position sets
(see chapter 5.2.5).
•
First carry out a test run, if necessary, without a work load
(see chapter 5.2.6).
•
If necessary, optimize the settings for position sets as well
as for the basis coordinates and the working area
(see chapter 5.2).
Festo P.BE-MTR-DCI-IO-EN en 1209d
•
After a successful test run you can teach the positions in
the position set table to which movement must be made.
5-15
Page 94
5. Commissioning
5.2.5 Teach position sets
Enter the position sets as follow s:
} Settings
Position set
Position no
Pos. set mode
Position
Velocity
Save
1. Activate the desired position set (0...14) with [Settings]
[Position set] [Position no].
2. Complete or correct the positioning mode of the position
set:
•
Select [Pos. set mode].
•
Set the positioning mode with the arrow buttons:
absolute = absolute position specification, related
to the project zero point
relative = relative position specification, related to
the current position.
•
Accept the value with OK <Enter>.
Note
After each change of the positioning mode, teach the
target position of the position set, otherwise the change of
positioning mode will not be accepted.
5-16
3. Teach the target position of the position set:
•
Select [Position].
•
Move the drive to the desired target position manually
with the arrow buttons.
•
Accept the position reached with OK <Enter>. The setting of the target position and the positioning mode
will then become effective in the drive.
4. Complete or correct the speed.
•
Select [Velocity].
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 95
5. Commissioning
•
Set the nominal speed with the arrow buttons.
•
Accept the setting with OK <Enter>. The setting will
then become effective in the drive.
5. Save the position set with [Save]. Only then will the
settings be retained even if the power supply is switched
off or if there is a power failure.
6. Enter the next position set.
Digitalization faults of the analogue-digital convertor can
accumulate in the case of relative position movements which
occur frequently one after the other and lead to deviations of
the position values. If necessary, insert an absolute position
set or homing run into the positioning cycle, in order to correct deviations.
5.2.6 Test run
Caution
Damage to components
During operation it is not permitted to move to the mech-
anical end positions (stops). If movement is made to the
end positions with a heavy load, jamming may occur in the
end positions.
•
Set the offset of the axis zero point ≠ 0.
•
Limit the positioning range by defining valid software
end positions during commissioning (see chapter 1.5.1).
•
Specify target positions only within the permitted positioning range.
Festo P.BE-MTR-DCI-IO-EN en 1209d
5-17
Page 96
5. Commissioning
1. Enter several position sets in order to check the positioning reaction (see chapter 5.2.5).
•
Set the target positions at the limits of the positioning
range in order to check the software end positions.
•
Set different speeds.
} Positioning
Demo posit tab
Move posit set
Homing
2. Select [Positioning] [Move posit set] in order to process a
certain position set - or -
3. Select [Positioning] [Demo posit tab] in order to process
all position sets. At least two position sets must be entered in the position set table.
With positioning run [Demo posit tab] all position sets
0...14 in the position set table will be processed one after
the other.
If the position set table contains a position set with speed
v = 0, neither this position set nor the following sets will
be processed; positioning run will be continued with position set 0.
With DEMO STOP <Enter> you can interrupt the positioning
cycle [Demo posit tab]. The current position set will be processed before the drive stops.
4. Start the test run.
5-18
•
Check the positioning reaction.
•
Check the displayed coordinates of the axis.
With EMERG.STOP <Menu> you can interrupt the current
positioning procedure.
5. If necessary, optimize the settings for position sets as well
as for the basis coordinates and the working area.
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 97
5. Commissioning
5.3 Commissioning with FCT
5.3.1 Installing the FCT
Note
The PlugIn MTR-DCI version V1.1.0 supports the following
motor units of MTR-DCI-...IO:
– MTR-DCI-32: Firmware version V-DME 1.20
– MTR-DCI-42: Firmware version V -DME 1.19 / 1.20
– MTR-DCI-52: Firmware version V-DME 1.19 / 1.20
– MTR-DCI-62: Firmware version V-DME 1.20
•
Check with later versions of the MTR-DCI to ascertain
whether an updated PlugIn is provided. If necessary
consult Festo.
Note
Administrator rights are required for installing the FCT.
The FCT is installed on your PC with an installation program.
The PlugIn MTR-DCI is installed on your PC together with the
installation program of the FCT.
1. Close all programs.
2. Place the Festo Configuration Tool CD in your CD ROM
drive. If Auto Run is activated on your system, installation
will start automatically and you can omit steps 3 and 4.
Festo P.BE-MTR-DCI-IO-EN en 1209d
3. Select [Execute] in the starting menu.
4. Enter D:\setup (if necessary replace D by the letter of your
CD ROM drive).
5. Follow the instructions on the display screen.
5-19
Page 98
5. Commissioning
5.3.2 Procedure for commissioning with the Festo Configuration Tool
Starting the FCT
Carry out the following steps in order to commission the
MTR-DCI with the FCT:
1. Connect the MTR-DCI to your PC via the RS232 interface.
Note here the instructions in chapter 3.4.
2. Starting the FCT: Double-click on the Festo Configuration
Tool icon on the desktop.
–or–
switch to Windows and select the entry [Festo Software]
[Festo Configuration Tool] in the menu [Start].
3. Create a project in the FCT or open an existing project.
Add a device to the project with the PlugIn MTR-DCI.
4. Create the device connection (online connection) between
thePCandtheMTR-DCIviatheFCTtoolbar.
It may be necessary here to have the same device names.
Device control
In order that the FCT can control the connected MTR-DCI, the
control interface of the MTR-DCI must be deactivated and
“Controller enable” must be set. The actual status of the
ENABLE input then has no effect. Switch to the window
“Project output”, then select the register “Operate” and
activate under “Device control” first the control box
“FCT/HMI” and then the control box “Enable”. The control
interface of the MTR-DCI will then be deactivated and Control
Enable will be set by the FCT.
5-20
Festo P.BE-MTR-DCI-IO-EN en 1209d
Page 99
5. Commissioning
Instructions on parametrizing and commissioning
Further information can be found in the help for the FCT with
the command [Help] [Contents FCT general] e.g.
– Help on working with projects and on inserting a device
into a project.
– Help on defining the measuring reference system
(referencing and basis coordinates).
The PlugIn MTR-DCI for the FCT supports all the steps necessary for commissioning an MTR-DCI.
With the PlugIn MTR-DCI for the FCT the necessary parametrizing can be carried out offline, i.e. without the MTR-DCI
being connected to the PC. This enables the actual commissioning to be prepared, e.g. in the design office when a new
system is being planned.
Further information can be found in the PlugIn help:
Command [Help] [Contents of installed PlugIns] [Festo
(manufacturer name)] [MTR-DCI (PlugIn name)] e.g.:
– for describing the dialogues of the “Device MTR-DCI”
– for describing the work steps for commissioning
– for the basic functions: Device connection, Device names,
Device control and for password protection.
Festo P.BE-MTR-DCI-IO-EN en 1209d
5-21
Page 100
5. Commissioning
5.4 Communication with the higher-order controller
5.4.1 I/O function check
Warning
Danger of injury. Faults in parametrizing can cause injury
to people and damage to property.
•
Enable the controller only if the drive system is correctly
installed and parametrized.
In order that the MTR-DCI can be controlled via the control
interface, the manual device control via the control panel /
FCT software must be deactivated:
– automatically when the operating voltage is switched on
(HMI = off)
– via the control panel of the MTR-DCI with the menu com-
mand [HMI control] (HMI = off)
– with FCT under “Device control” in the window “General
output”, (FCT = off).
In order to check the configuration and the axis set-up, enter
a simple test program or simulate control by directly setting
the inputs.
•
Please refer here to the function description of the control
interface in chapter 5.4.2.
•
Provide the necessary system inputs on the MTR-DCI.
There must be a 1-signal at the ENABLE input (controller
and power end stage enabled).
5-22
•
Take into account also the output signals. There will be a
1-signal at the READY output (readiness to operate) if the
controller and the power end stage are enabled and if no
fault has been recognized.
•
Program or start homing run as well as some positioning
movements.
•
Check the positioning reaction.
Festo P.BE-MTR-DCI-IO-EN en 1209d
 Loading...