

Page 1
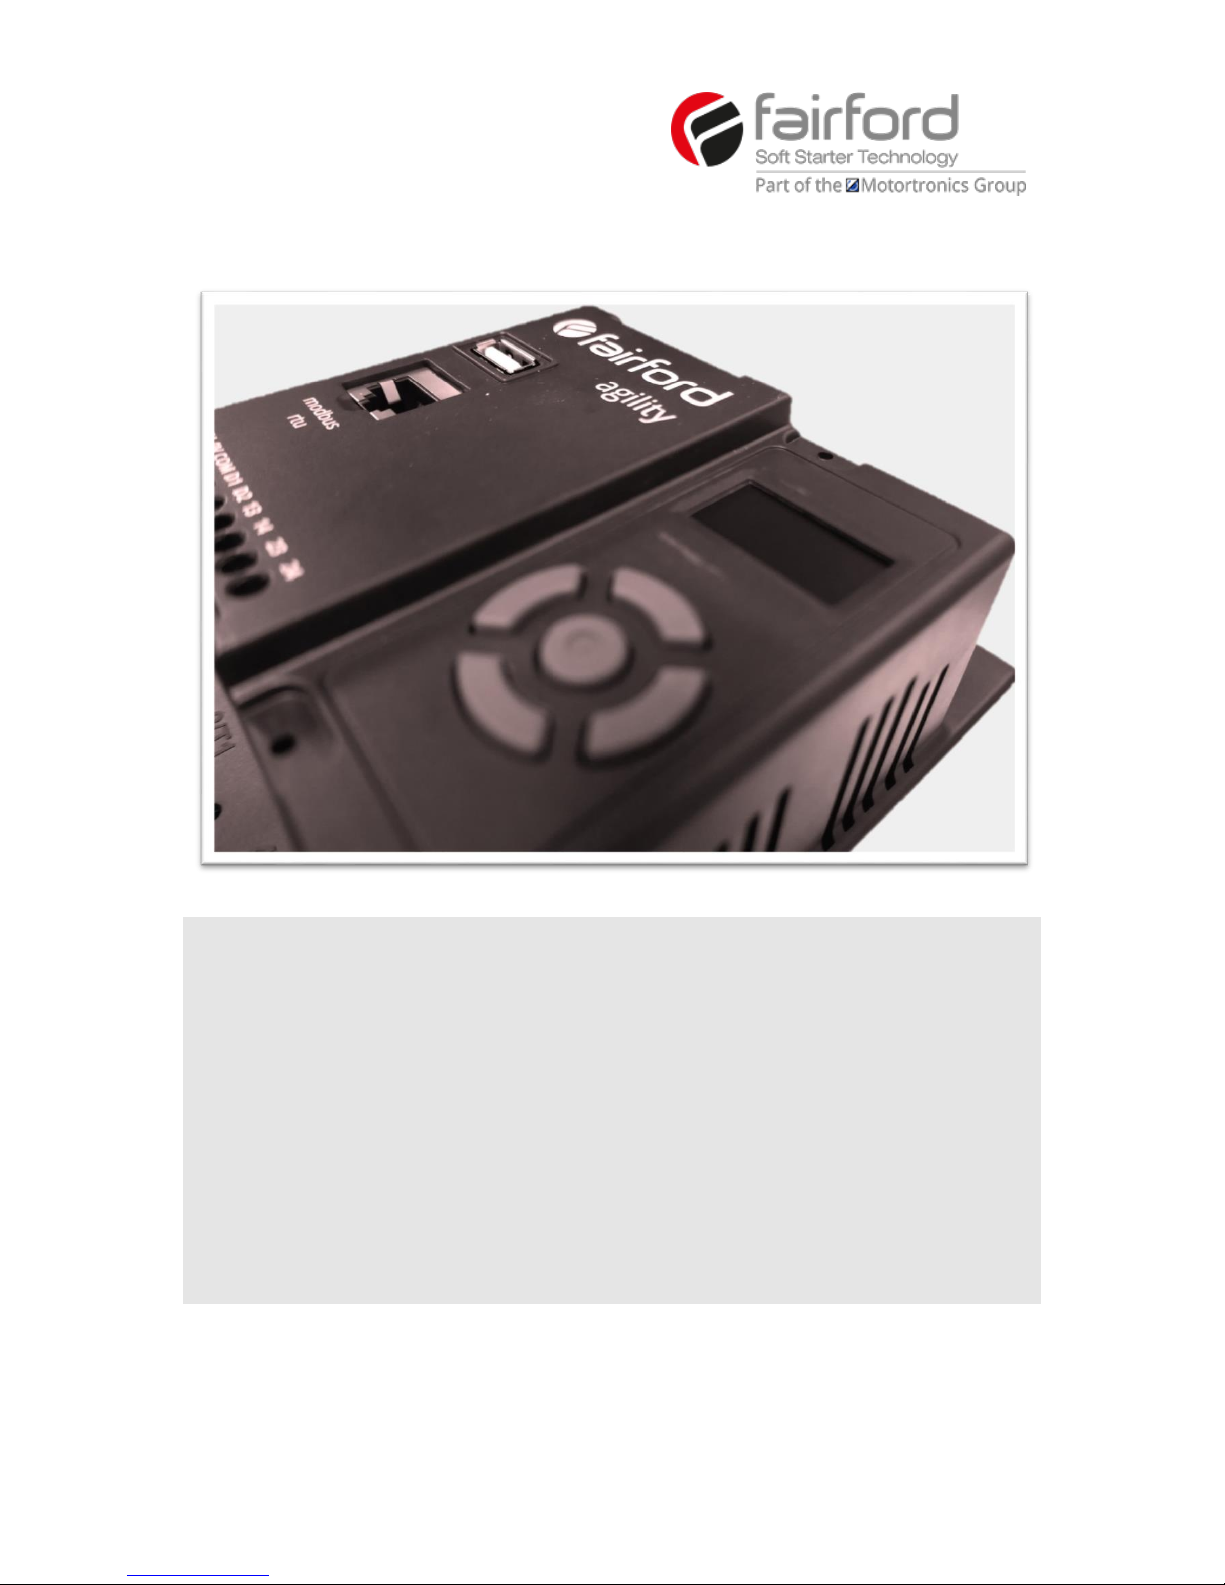
Innovation in soft starter technology
agility
TM
USER MANUAL
MAN-AGY-001. Version 06
Page 2
1
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
agility
TM
user manual
© Fairford Electronics Ltd
Bristow House
Gillard Way, Ivybridge
PL21 9GG
UK
www.fairford.com
© 2019 by Fairford Electronics, all rights reserved
Copyright subsists in all Fairford Electronics deliverables including magnetic, optical and/or any
other soft copy of these deliverables. This document may not be reproduced, in full or in part,
without written permission. Enquiries about copyright of Fairford Electronics deliverables should
be made to Fairford Electronics Ltd. If, by permission of the copyright owner, any part of this
document is quoted, then a statement specifying the original document shall be added to the
quotation. Any such quotation shall be according to the original (text, figure or table) and may
not be shortened or modified.
Page 3
2
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Contents
Safety .................................................................................................................................. 6
Installation ......................................................................................................................... 7
Mounting ...................................................................................................................................... 7
Requirements for an Enclosure ................................................................................................. 7
Enclosure Ventilation .................................................................................................................. 7
Altitude Derate ............................................................................................................................ 7
Handling ....................................................................................................................................... 8
Accessories ................................................................................................................................... 8
Dimensions AGY-101 to AGY-113 .............................................................................................. 9
Dimensions AGY-201 to AGY-205 .............................................................................................. 10
Dimensions AGY-301 to AGY-305 .............................................................................................. 11
Horizontal Mounting .............................................................................................................. 12
Environmental Specifications .................................................................................................. 12
Electrical Installation ...................................................................................................... 13
Warnings .................................................................................................................................... 13
Electrical Supplies ..................................................................................................................... 13
Electromagnetic Compatibility .................................................................................................. 17
Motor Overload Protection ...................................................................................................... 20
Electrical Connections .............................................................................................................. 21
Main Circuit Wiring Diagram .................................................................................................... 21
Single Phase Operation ............................................................................................................. 22
Control Terminal Connection ................................................................................................... 23
Control Terminal Functions ..................................................................................................... 23
Digital Input 2 (D2) Selectable Functions ................................................................................ 23
Digital Output 21/22 Selectable Functions ............................................................................. 23
3-Wire Control Circuit Wiring Diagram ................................................................................... 24
2-Wire Control Wiring Diagram ................................................................................................ 24
Display and Controls ................................................................................................................. 25
Auto Setup Procedure (Auto App)............................................................................................ 27
Setup by Individual Parameter Settings (Advanced) ............................................................. 27
Auto Application Setup Parameter Settings .......................................................................... 27
Menu Structure ................................................................................................................ 28
Function Descriptions ..................................................................................................... 33
Trip and Fault Codes ........................................................................................................ 42
Page 4
3
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset Function ........................................................................................................ 45
Auto Reset Assignable Trips .................................................................................................... 46
Auto Reset Function Descriptions ........................................................................................... 47
Communication ............................................................................................................... 60
Modbus RTU Serial Communications ...................................................................................... 60
Modbus RTU Communications Interface ................................................................................ 60
Modbus RTU Connections ......................................................................................................... 60
........................................................................... 61
................................................................................................................ 61
...................................................................................... 61
..................................................................................................................................... 61
......................................................................................................................... 61
.................................................................................................................................. 61
CRC .............................................................................................................................................. 62
............................................................................................................. 62
....................................................................................................... 63
Modbus RTU Parameters ................................................................................................ 64
Memory Map .............................................................................................................................. 64
Message Timing ......................................................................................................................... 64
Special Modbus Registers ....................................................................................................... 119
Modbus PNU Alphabetical Cross Reference ......................................................................... 125
Updating Firmware ....................................................................................................... 127
Update Procedure ................................................................................................................... 127
Instruction for Updating ......................................................................................................... 127
Applications .................................................................................................................... 129
Motor Suitability and Associated Considerations ............................................................... 129
Suitability ................................................................................................................................. 129
Induction Motor Characteristics............................................................................................ 129
Rating........................................................................................................................................ 129
Maximum Motor Cable Length .............................................................................................. 130
Power Factor Correction Capacitors ..................................................................................... 130
Lightly Loaded, Small Motors ................................................................................................. 130
Motors Fitted with Integral Brakes ....................................................................................... 130
Older Motors ............................................................................................................................ 130
Wound-rotor or Slip-ring Motors ........................................................................................... 130
Page 5
4
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Enclosures ................................................................................................................................ 130
EU Compliance with the EMC Directive ................................................................................. 131
Fuses ......................................................................................................................................... 131
Rules for Specific Applications ............................................................................................... 131
High Inertia Loads ................................................................................................................... 131
Frequent Starting .................................................................................................................... 131
Soft-Stopping ........................................................................................................................... 131
Reversing Configuration ......................................................................................................... 132
Replacement of Fluid Couplings ............................................................................................ 132
Two-speed Motor Applications .............................................................................................. 132
Overhauling Loads .................................................................................................................. 132
Application Table ..................................................................................................................... 132
Concepts and principles of fixed-speed induction motor starting and control. .............. 134
Introduction ............................................................................................................................. 134
The Induction Motor ............................................................................................................... 134
Starting Induction Motors ...................................................................................................... 137
Electro-Mechanical Methods Of Starting .............................................................................. 138
The Semiconductor Motor Controller ................................................................................... 140
Running Induction Motors ..................................................................................................... 141
Reliability Considerations ...................................................................................................... 142
Accessory Installation ................................................................................................... 144
Power Supply AGY-020 and AGY-021 ...................................................................................... 144
Connections ............................................................................................................................. 145
Control Terminal ..................................................................................................................... 145
Functions .................................................................................................................................. 145
3-Wire Control Using AGY-020/021 ......................................................................................... 146
2-Wire Control Using AGY-020/021 ......................................................................................... 146
Fan (AGY-030) ........................................................................................................................... 147
Remote Keypad (AGY-010) ...................................................................................................... 148
Network Connection ............................................................................................................... 148
Keypad Connection and Operation ............................................................................. 149
Operation ................................................................................................................................. 149
Initial Power-Up ....................................................................................................................... 149
Selecting Units To Monitor/Configure ................................................................................... 150
Keypad Installation ....................................................................................................... 152
Page 6
5
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Mounting .................................................................................................................................. 152
Sizing Guide .................................................................................................................... 153
Key to Part Numbers ............................................................................................................... 154
Notes ............................................................................................................................... 154
Page 7
6
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Important information
Installers should read and understand the instructions in this guide prior to installing, operating
and maintaining the soft starter. The following symbols may appear in this guide or on the soft
starter to warn of potential hazards or to draw attention to certain information.
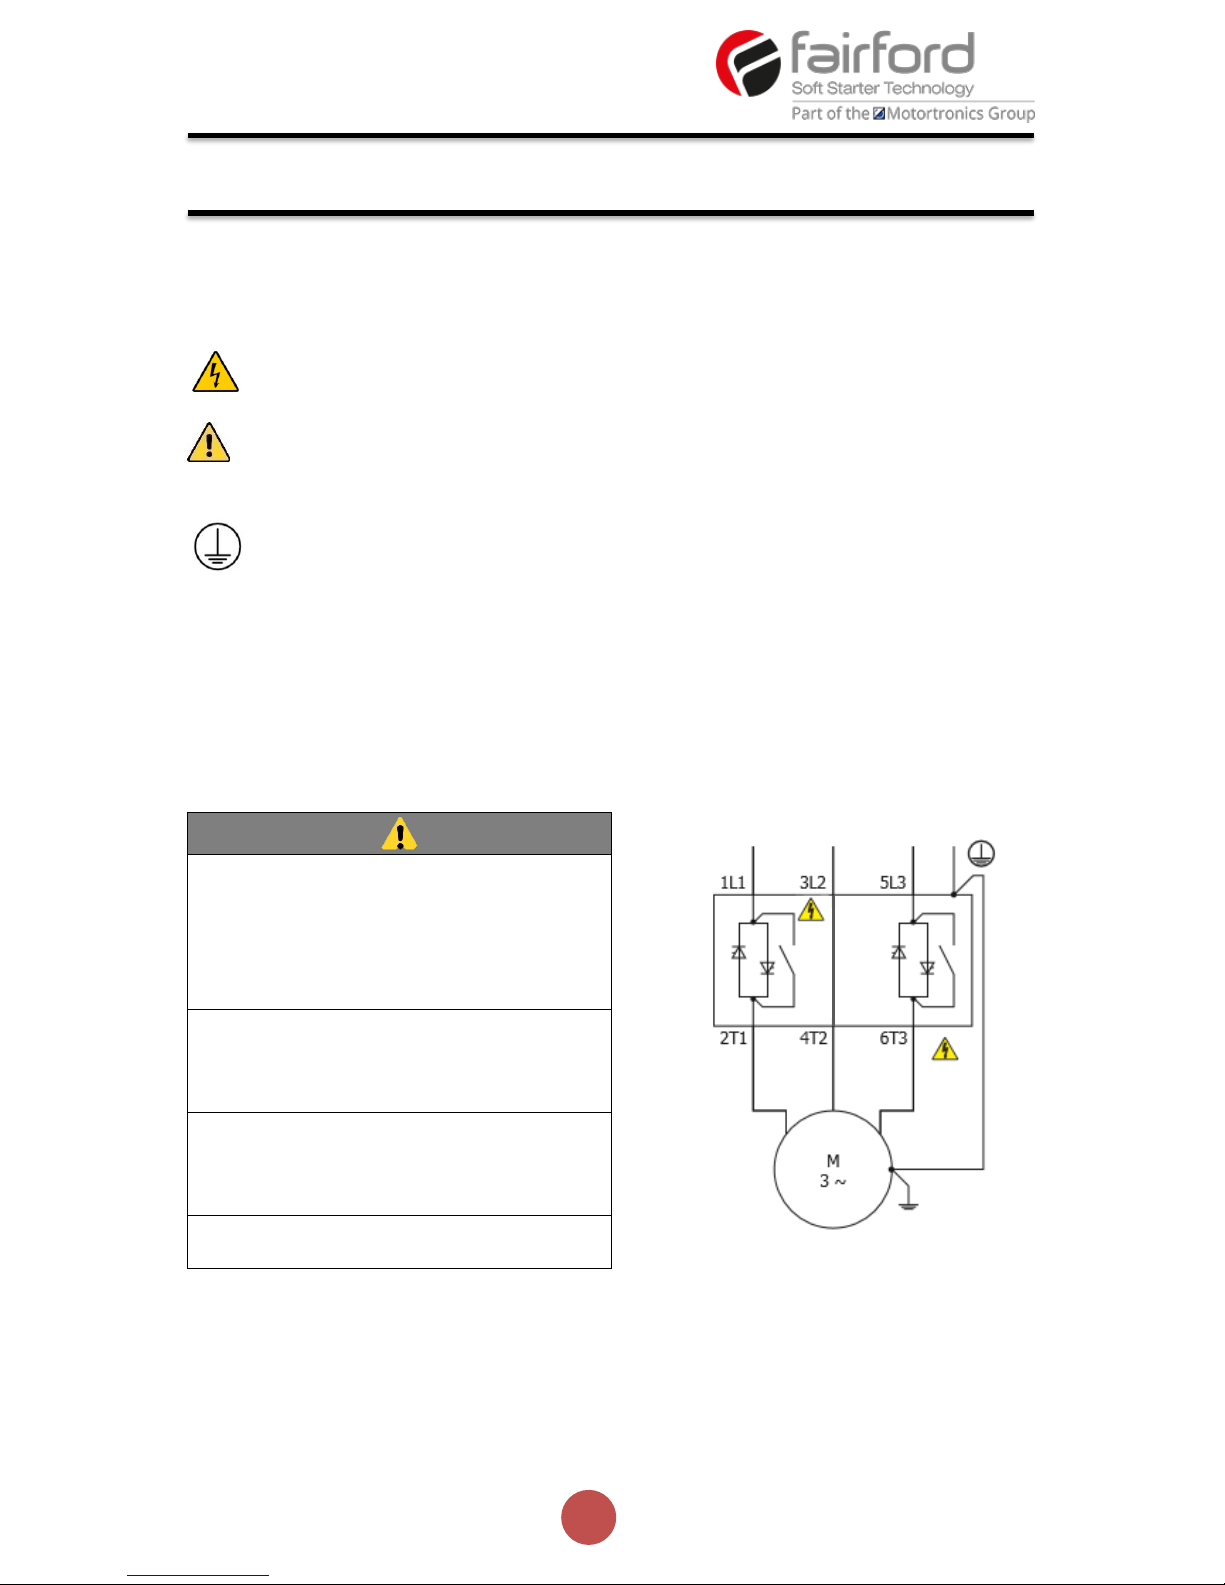
Dangerous Voltage
Indicates the presence of a hazardous voltage which could result in personal injury or death.
Warning/Caution
Indicates a potential hazard. Any instructions that follow this symbol should be obeyed to avoid
possible damage to the equipment, and personal injury or death.
Protective Earth (Ground)
Indicates a terminal which is intended for connection to an external conductor for protection
against electric shock in case of a fault.
Caution Statements
The examples and diagrams in this manual are included solely for illustrative purposes. The
information contained in this manual is subject to change at any time and without prior notice.
In no event will responsibility or liability be accepted for direct, indirect or consequential
damages resulting from the use or application of this equipment.
• agilityTM soft starters contain dangerous
voltages when connected to the mains
supply. Only qualified personnel that have
been completely trained and authorised,
should carry out installation, operation and
maintenance of this equipment.
• Installation of the soft starter must be made
in accordance with existing local and national
electrical codes and regulations and have a
minimum protection rating.
• It is the responsibility of the installer to
provide suitable grounding and branch circuit
protection in accordance with local electrical
safety codes.
• This soft starter contains no serviceable or
re-usable parts.
Safety
Page 8
7
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Mounting
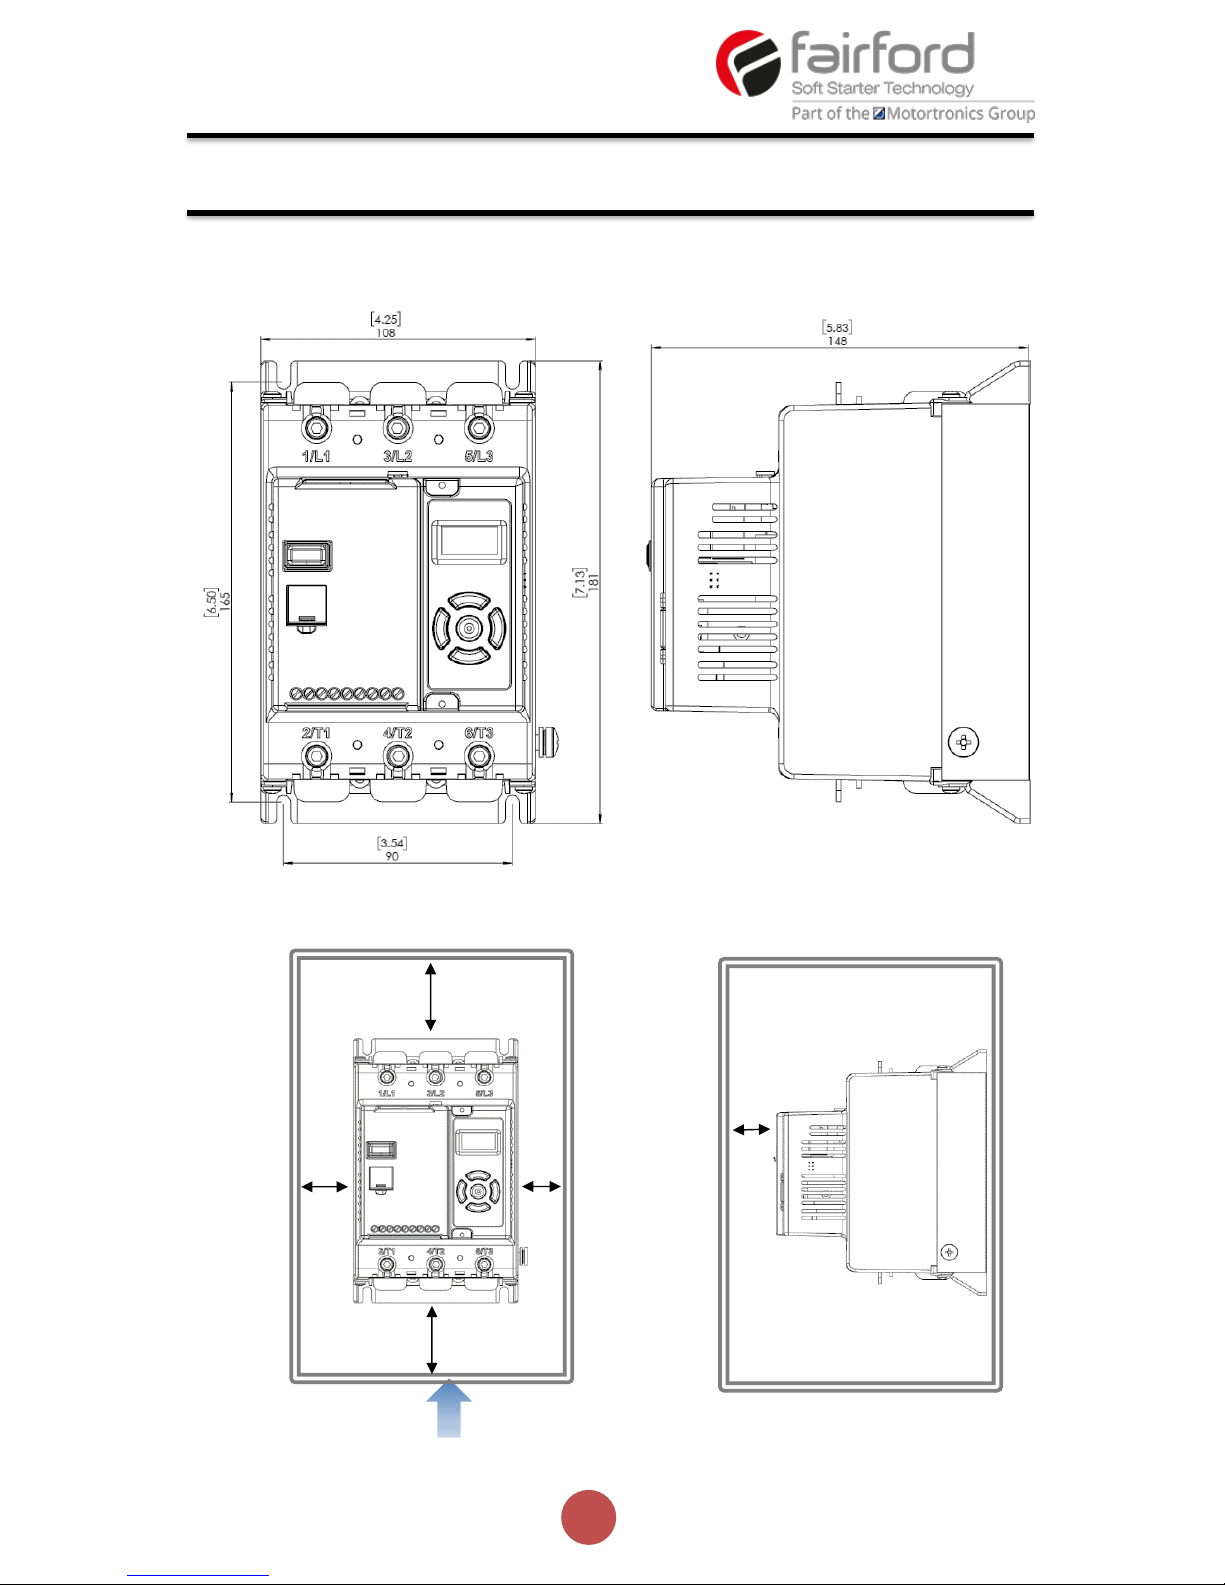
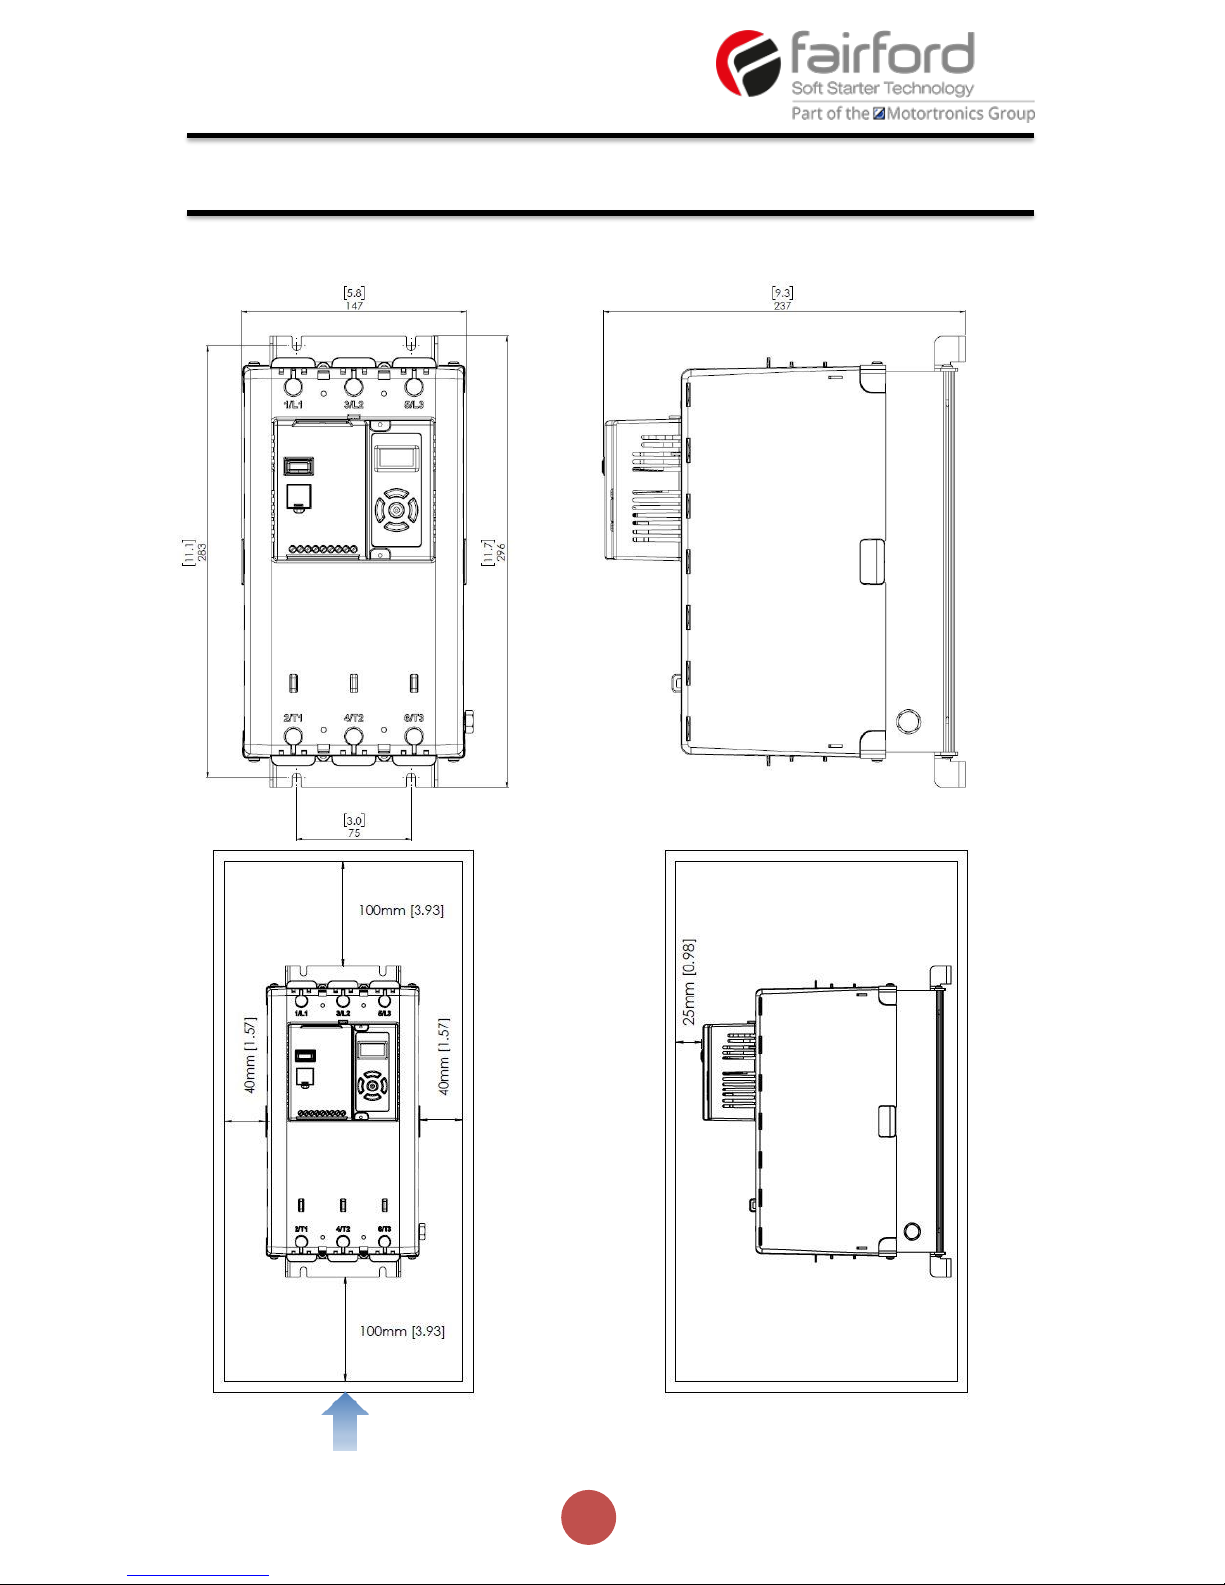
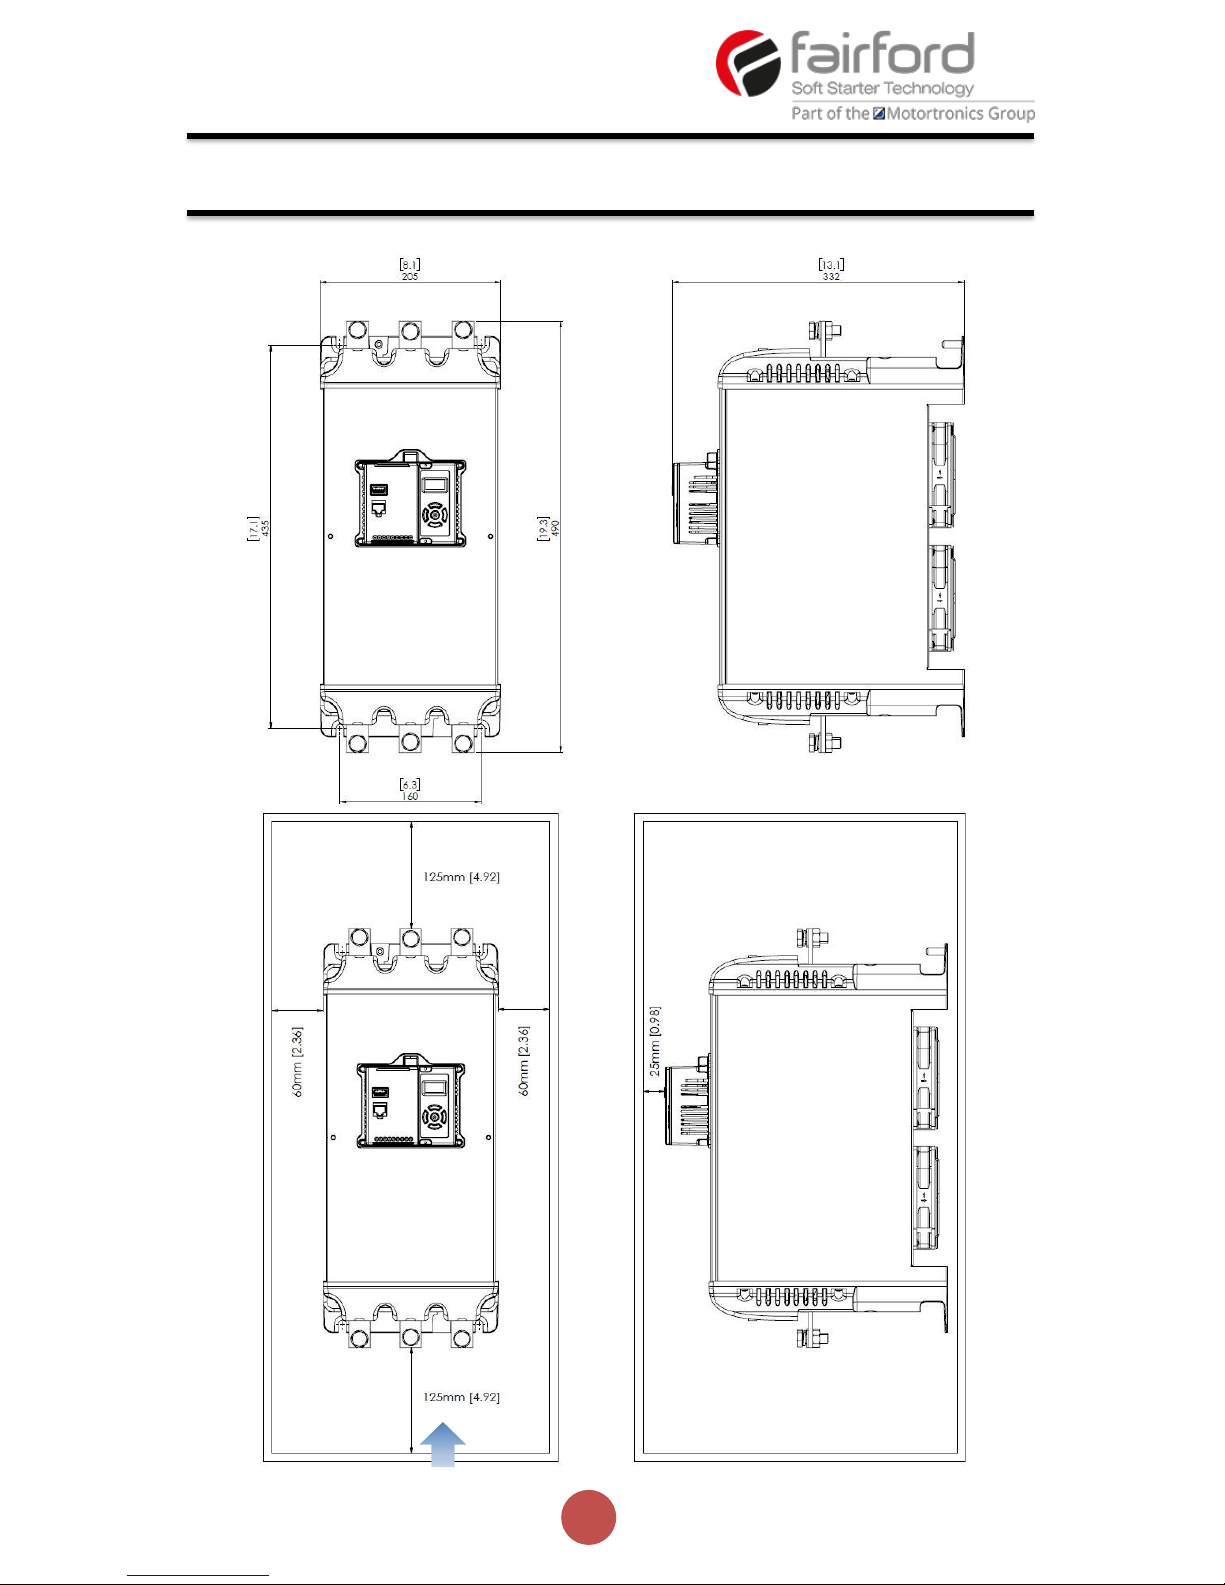
Fix the unit to a flat, vertical surface using the mounting holes (or slots) on its base-plate. The
mechanical outline diagrams, shown on Page 8, give the dimensions and mounting hole
positions for each model. Ensure that:
• The orientation of the unit has the ‘TOP’ uppermost (unless horizontally mounted –
see page 9).
• The location allows adequate front access.
• The screen can be viewed.
Do not install other equipment that generates significant heat close to the soft starter.
Requirements for an Enclosure
For a typical industrial environment, an enclosure would provide the following:
• A single location for the unit and its protection/isolation switch-gear.
• The safe termination of cabling and/or bus-bars.
• Means to effect proper air flow through the enclosure.
Enclosure Ventilation
When fitting agilityTM into a cabinet, ventilation must be provided. The heat dissipated can be
approximated with the formula: -
Starting
Watts (agilityTM) = start current(A) x start time(s) x number of starts per hour/ 1800
Running
Watts(agilityTM) = 0.4 x running amps
Use the following formula to determine the fan requirement. An allowance has been
incorporated into the formula so that the figure for Q is the air delivery in the fan supplier’s
data.
Q = (4 x Wt / (T
max-Tamb
))
Q = volume of air (cubic metres per hour-m3/h)
Wt = Heat produced by the unit and all other heat sources within the enclosure (Watts) T
max
=
Maximum permissible temperature within the enclosure (40°C for a fully rated agility™)
T
amb
= Temperature of the air entering the enclosure (°C) [to work in CFM, substitute °F for °C. Q is now
in CFM]
Altitude Derate
Altitude above sea level 1000m (3281ft). Above 1000m de rate by 1% of agility™ Ie per 100m
(328ft) to a maximum altitude of 2000m (6562ft)
Ambient Temperature Derate
-20°C (-4°F) to 40°C (104°F). Above 40°C de-rate linearly by 2% of agility™ Ie per °C to a maximum
of 60°C (140°F).
Installation
Page 9
8
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Handling
The agility soft start range comprises 3 frame sizes, with various weights and dimensions. See
pages 5-7 for further information.
Prior to installing the agility unit, the installer should carry-out a risk assessment. If considered
appropriate, a suitable handling device should be used.
Do not lift the agility unit by attachment to the 3-phase terminal connections or busbars.
WARNING
HANDLING AND LIFTING HAZARD
Ensure the area below any equipment is clear of all personnel and property.
Failure to follow this practice may result in death, serious injury, or damage to
equipment.
Accessories
The following accessories have been developed and tested for use with the agility range of soft
starts:
AGY-010 Remote keypad for AGY-101 to AGY-305. Provides remote functionality for up to 32 soft
starter units
AGY-020 100Vac – 240Vac power supply. Provides mains voltage control power and digital
control functionality. For use with AGY-101 to AGY-113 only.
AGY-021 100Vac – 240Vac power supply. Provides mains voltage control power and digital
control functionality. For use with AGY-101 to AGY-305.
AGY-030 Cooling fan accessory for AGY-101 to AGY-113 only. Increases the number of starts per
hour (see page 19)
AGY-031 Cooling fan accessory for AGY-201 to AGY-209 only. Increases the number of starts per
hour (see page 19)
Installation (continued)
Page 10
9
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Dimensions AGY-101 to AGY-113
[ ] = inch
Weight 1.97kg (3.75lb)
Fitting
Air Flow
Installation (continued)
25mm [0.98]
25mm [0.98]
75mm [2.95]
75mm [2.95]
25mm [0.98]
Page 11
10
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Air Flow
Dimensions AGY-201 to AGY-205
Weight 6 kg [13.22LB]
Installation (continued)
[ ] = inch
Page 12
11
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Air Flow
Dimensions AGY-301 to AGY-305
Weight 15kg [33.10lb]
Installation (continued)
[ ] = inch
Page 13
12
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
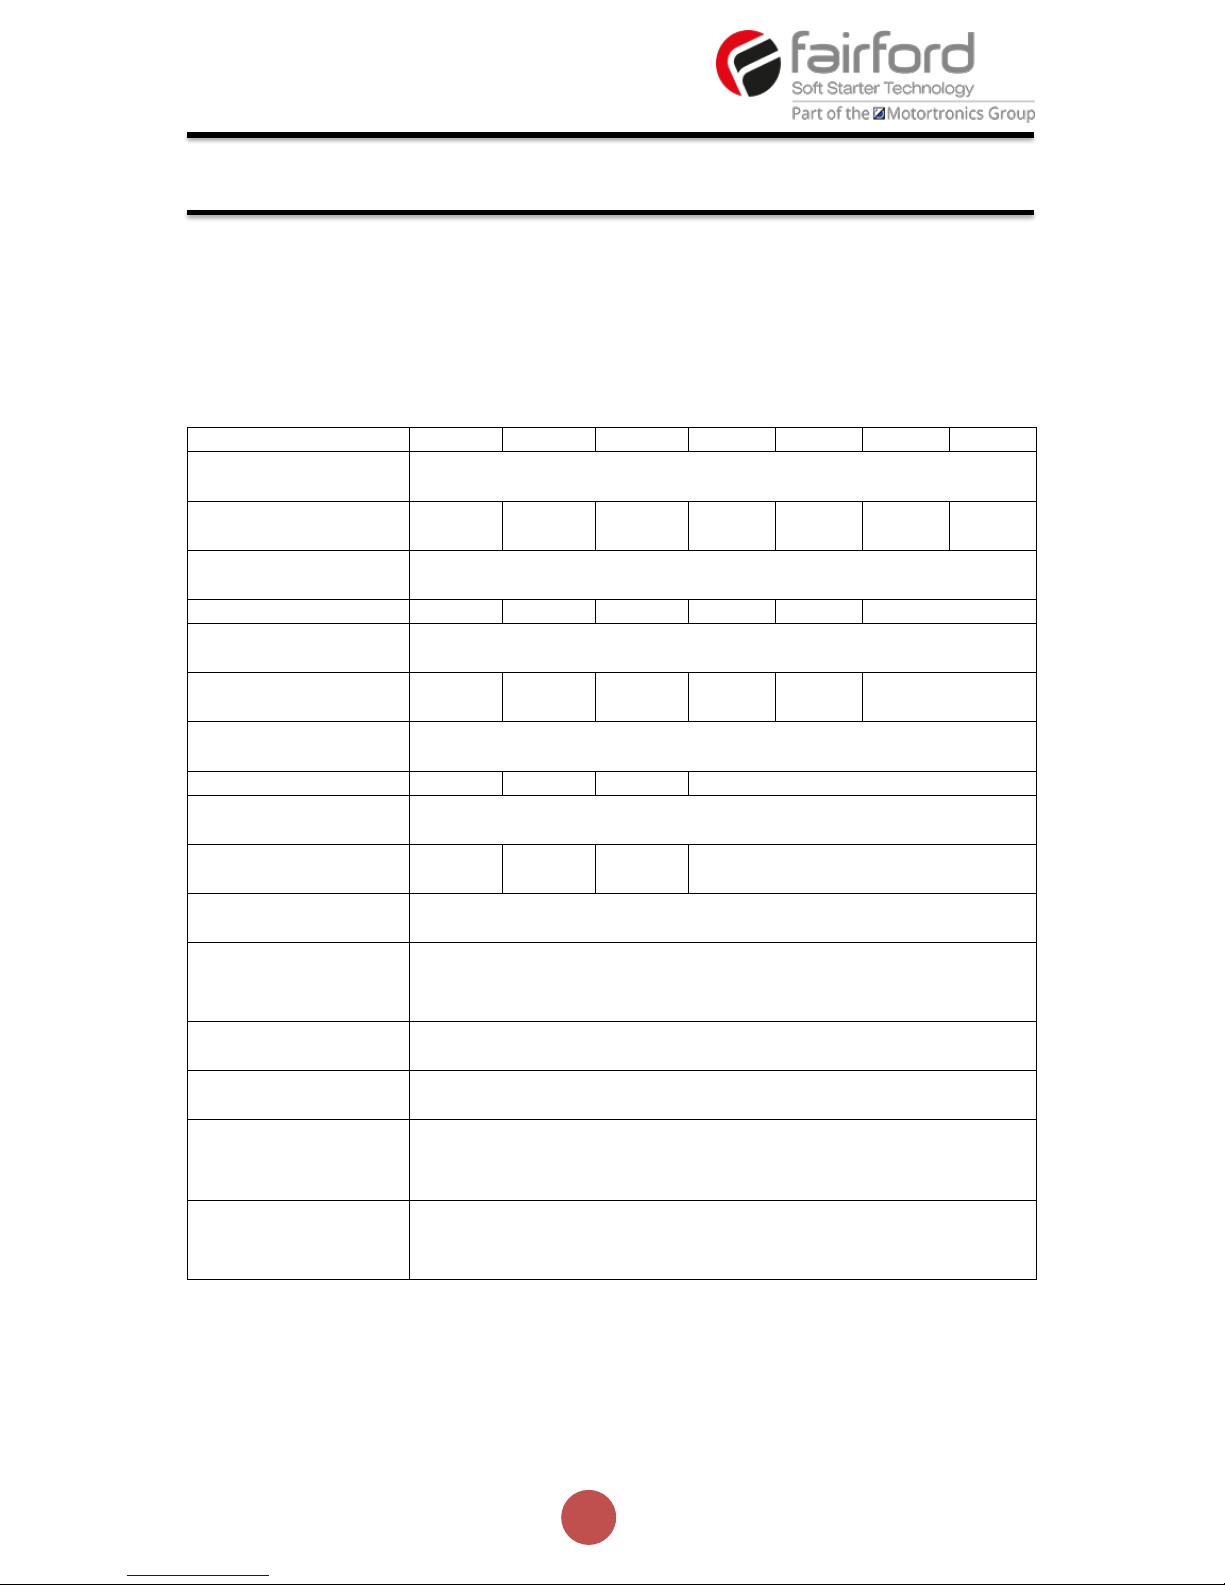
Horizontal Mounting
The agility
TM
unit may be mounted horizontally if required. It will be necessary to apply a deration
to the unit power in this instance – see Horizontal Rating Table (Page 13)
Environmental Specifications
Model (AGY-)
101
103
105
107
109
111
113
Frame Size
1
Heat output (W)
9
12
14
16
20
25
30
Weight kg [lb]
1.97 [4.20]
Model (AGY-)
201
203
205
207
209
Frame Size
2
Heat output (W)
37
49
61
74
90
Weight kg [lb]
AGY-201-AGY207 6.00 [13.23] AGY-209 6.30 [13.89]
Model (AGY-)
301
303
305
Frame Size
3
Heat output (W)
111
139
166
Weight kg [lb]
15.00 [33.10]
Ambient Operating
Temp.
-20°C [-4°F] to 40°C [104°F] ; above 40°C derate linearly by 2% of
agility Ie per °C to a maximum of 60°C (140°F)
Transportation and
Storage Temperature
-20°C to 70°C [-4°F to 158°F] continuous
Humidity
max 85% non-condensing, not exceeding 50% @ 40°C [104°F]
Maximum Altitude
1,000m [3281ft] ; above 1000m derate by 1% of agility Ie per 100m
(328ft) to a maximum altitude of 2,000m (6562ft)
Environmental Rating
Main Circuit: IP00 (IP20 with finger guards);
Control Circuit: IP20; No corrosive gases permitted
Installation (continued)
Page 14
13
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Warnings
Isolation
Caution: agilityTM uses semiconductor devices in the main circuit and is not designed to
provide isolation. For this reason isolation means must be installed in the supply circuit
in accordance with the appropriate wiring and safety regulations
Electrical Control Supply Requirements
All electrical connections are made to power input and output terminals, control
terminals and an earth stud.
Fuse Protection
The Mains Supply and the Control Supply each require protection. Although all units have
electronic overload protection for the Soft Starter, the installer should always fit fuses, for motor
protection, between the unit and the Mains Supply, not between the unit and the motor.
Semiconductor fuses can be supplied as an option for short-circuit protection of the
semiconductors. These fuses must be fitted externally to the agilityTM chassis to comply with
certain standards. It is the responsibility of the installer and system designer/specifier to ensure
that the required standards or regulations are not affected by so doing.
Safety
agilityTM soft starters contain hazardous voltages when connected to the electrical power
supply. Only qualified personnel who are trained and authorized should carry out
installation, operation and maintenance of this equipment. Refer to and carefully follow all of the
‘Warnings’ section at the beginning of this user manual, as well as other warnings and notes
throughout the manual.
Electrical Supplies
The unit requires a 3-phase balanced Mains Supply to provide the power for the controlled
motor, and a 24Vdc for the internal control circuitry. The unit will not operate unless the control
supply voltage is within the specified limits.
Electrical Installation
Page 15
14
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
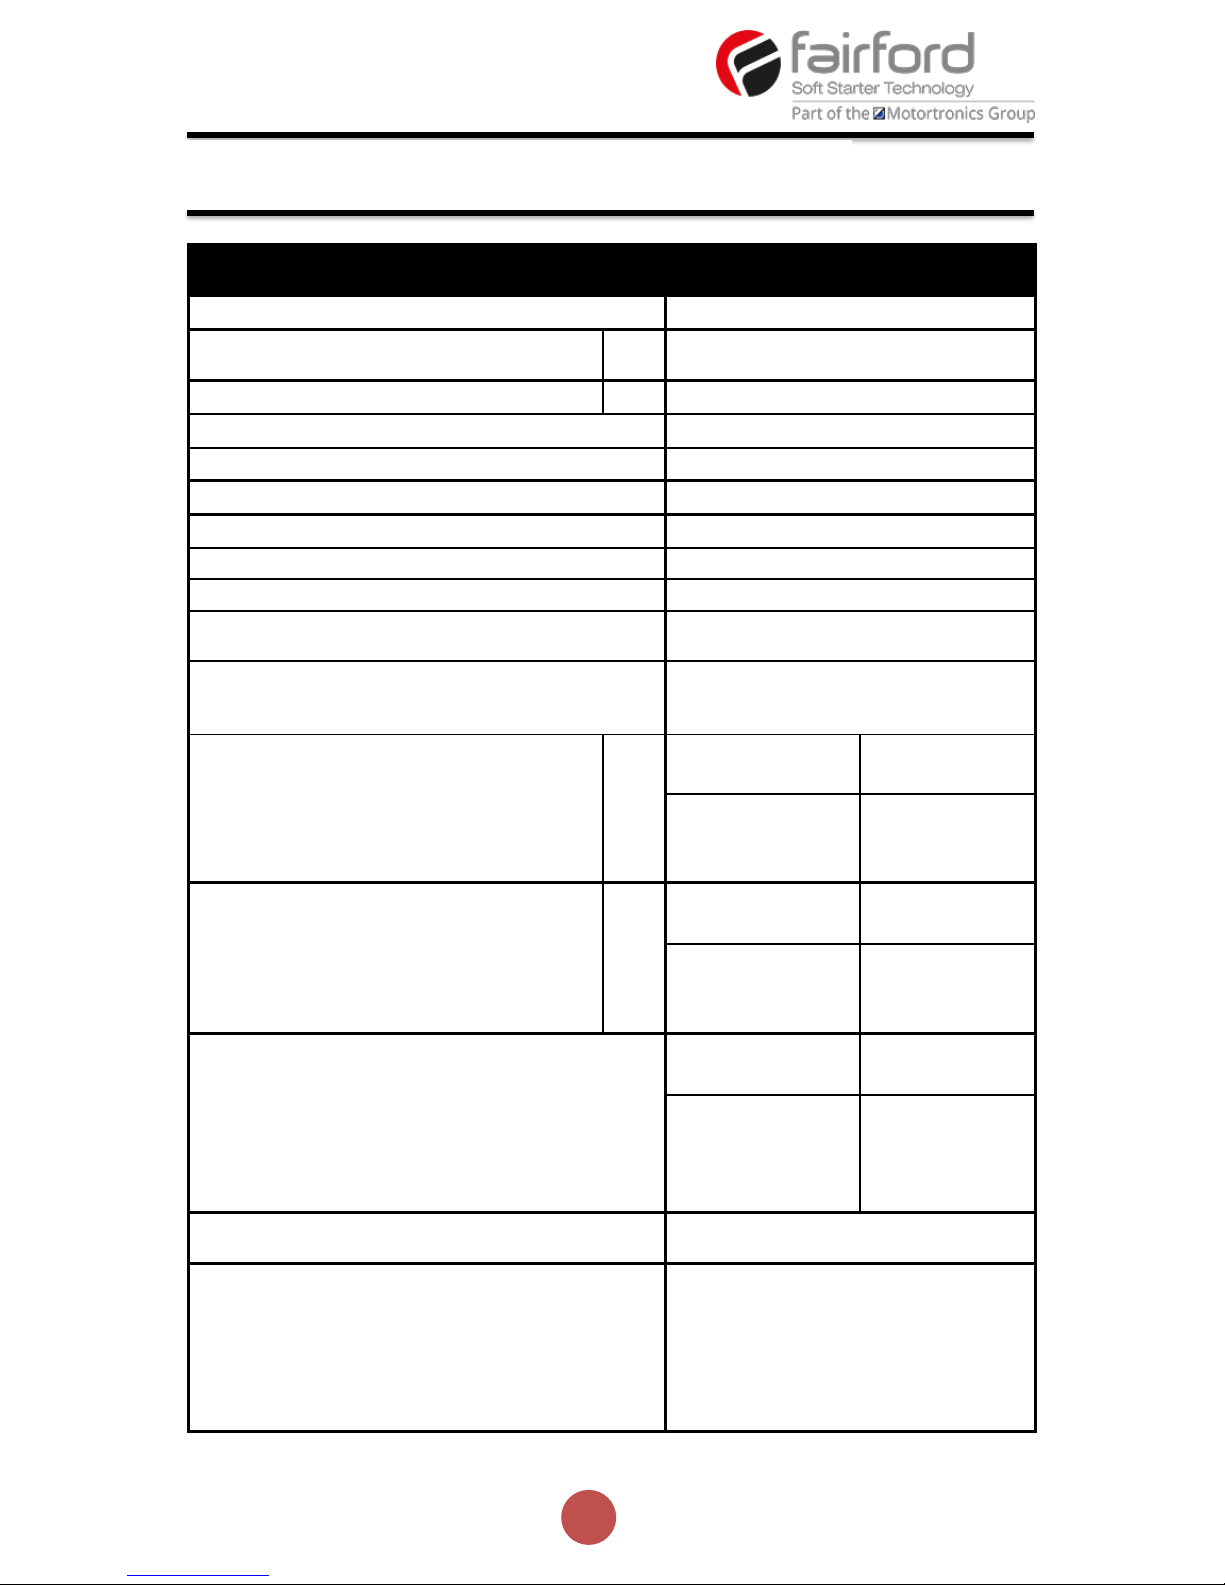
General Specification
Product Standard
EN 60947-4-2: 2012
Rated operational voltages
Ue
200Vac to 600Vac (See Key to part numbers)
Rated operational current
Ie
See Rating Table
Rating index
See Rating Table
Rated frequencies
50 - 60Hz ± 5Hz
Rated duty
Uninterrupted.
Form designation
Form 1, Internally Bypassed
Method of operation
Symmetrically controlled starter
Method of control
Semi-automatic
Method of connecting
Thyristors connected between motor
windings and supply
Number of poles
3 main poles, 2 main poles controlled by
semiconductor switching element
Rated insulation voltage
Ui
Main circuit
See Key to part
numbers
Control supply circuit
230V a.c. r.m.s 1)
Rated impulse withstand voltage
U
imp
Main circuit
6 kV
Control supply circuit
4 kV 1)
IP code
Main circuit
IP00 (IP20 with
finger guards)
Supply and Control
circuit
IP20
Overvoltage Category / Pollution degree
III / 3
Rated conditional short-circuit current and type of coordination with associated short circuit protective
device (SCPD)
Type 1 co-ordination
See Short Circuit Protection Tables for rated
conditional short-circuit current and
required current rating and characteristics
of the associated SCPD
Electrical Installation (continued)
Page 16
15
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
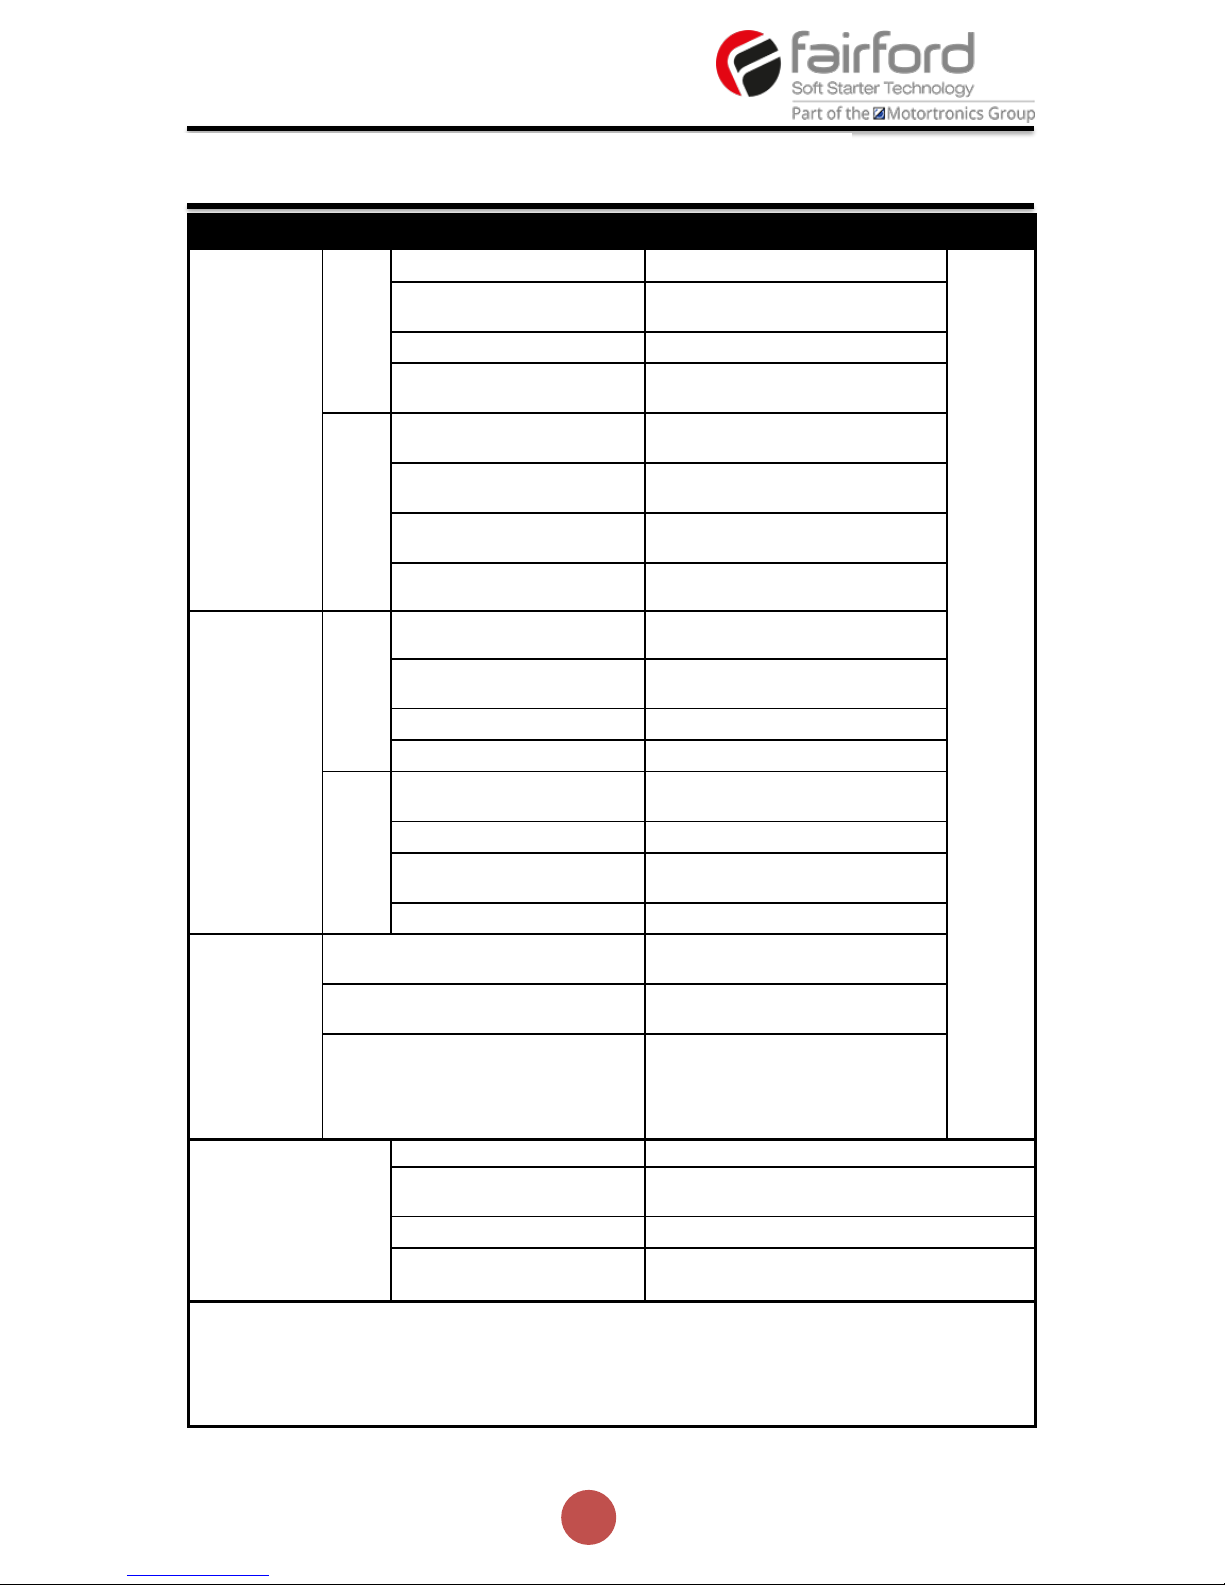
General specification (Continued)
As
Standard
Control
Supply input
0, 24V
Supply
2)
Kind of current, rated
frequency
d.c.
Rated voltage Us
24Vd.c.
Maximum power
consumption
12VA
Control
Programmable opto-isolated
inputs
D1, D2
circuit
2)
Common input, marking
COM
Kind of current, rated
frequency
d.c.
Rated voltage Uc
24Vd.c.
Protect
with 4A
With
AGY-020/ AGY021
module
Control
Supply input
L, N
UL listed
fuse
Supply
Kind of current, rated
frequency
a.c., 50 - 60Hz ± 5Hz
Rated voltage Us
110V to 230V a.c.
Rated input current
1A
Control
Programmable opto-isolated
inputs
D1, D2
circuit
Common input
COM
Kind of current, rated
frequency
a.c., 50 - 60Hz ± 5Hz
Rated voltage Uc
110V to 230V a.c.
Auxiliary
Circuit 3)
Form A – Single gap make -contact
(normally open)
13, 14
Form B – Single gap break-contact
(normally closed)
21, 22
Utilization category, voltage rating,
current rating
Resistive load, 250Vac, 2A.
Cosø =0.5, 250Vac, 2A 4)
Electronic
overload relay
with manual reset and
thermal memory
Trip Class
10 (factory default), 20 or 30 (selectable)
Current setting
See Electronic Overload Relay Current Settings
Rated frequency
50 to 60Hz ± 5Hz
Time-current characteristics
See trip curves (Trip time Tp ± 20%)
1)
With optional AGY-020 or AGY-021 power supply module. AGY-020 TO BE USED WITH AGY-101 TO AGY-113 ONLY
2)
Must be supplied by class 2, limited voltage current or protected by a 4A UL 248 listed fuse.
3)
Compliant with Annex S of IEC 60947-1:2007 at 24Vd.c.
4)
Not applicable for UL.
5)
The safety functions were not evaluated by UL. Listing is accomplished according to requirements of Standard UL 508 and CSA14 -13,
general use applications
Electrical Installation (continued)
Page 17
16
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
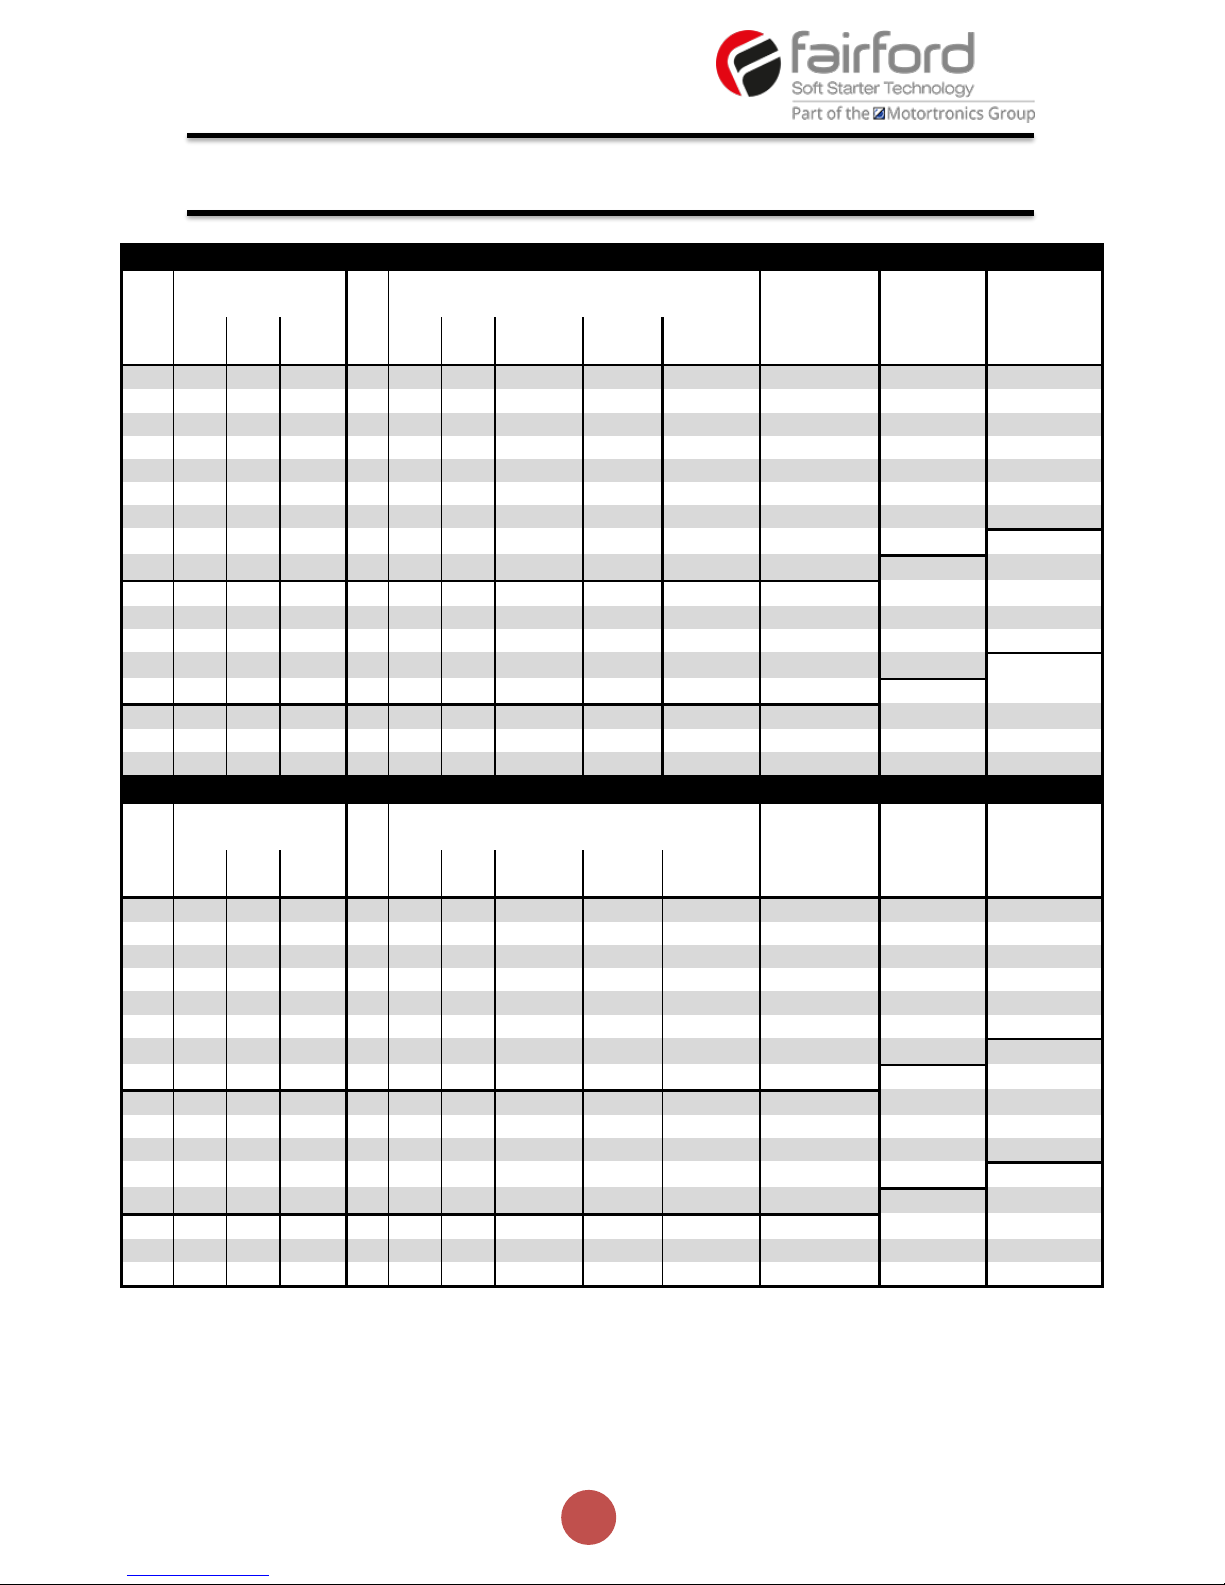
Rating Table – Vertically Mounted
Ie
kW 1)
FLA
Hp 2)
Trip Class 10
Trip Class
20
Trip Class 30
A 3)
230V
400V
500V 4)
A 3)
200V
208V
220-240V
440-480V
550-600V 4)
Ie: AC-53a:
3.5-17: 90-5
5)
Ie: AC-53a:
4-19: 90-5 5)
Ie: AC-53a:
4-29: 90-5 5)
17 4 7.5
7.5
17 3 5 5 10
15 - -
AGY-101
17 4 7.5
7.5
17 3 5 5 10
15
-
AGY-101
AGY-103
17 4 7.5
7.5
17 3 5 5 10
15
AGY-101
AGY-103
AGY-105
22
5.5
11
11
22 5 5
7.5
15
20
AGY-103
AGY-105
AGY-107
29
7.5
15
15
27
7.5
7.5
7.5
20
25
AGY-105
AGY-107
AGY-109
35
7.5
18.5
22
34
10
10
10
25
30
AGY-107
AGY-109
AGY-111
41
11
22
22
41
10
10
10
30
40
AGY-109
AGY-111
AGY-113
55
15
30
37
52
15
15
15
40
50
AGY-111
AGY-113
AGY-201
66
18.5
37
45
65
20
20
20
50
60
AGY-113
AGY-201
AGY-203
80
22
45
55
77
20
25
25
60
75
AGY-201
AGY-203
AGY-205
106
30
55
75
100
30
30
30
75
100
AGY-203
AGY-205
AGY-207
132
37
75
90
125
40
40
40
100
125
AGY-205
AGY-207
AGY-209
160
45
90
110
156
50
50
60
125
150
AGY-207
AGY-209
AGY-301
195
55
110
132
192
60
60
60
150
200
AGY-209
AGY-301
AGY-303
242
75
132
160
242
75
75
75
200
250
AGY-301
AGY-303
AGY-305
302
90
160
200
302
100
100
100
250
300
AGY-303
AGY-305
-
361
110
200
250
361
125
125
150
300
350
AGY-305
-
-
Rating Table – Horizontally Mounted
Ie
kW 1)
FLA
Hp 2)
Trip Class 10
Trip Class
20
Trip Class 30
A 3)
230V
400V
500V 4)
A 3)
200V
208V
220-240V
440-480V
550-600V 4)
Ie: AC-53a:
3.5-17: 90-5
5)
Ie: AC-53a:
4-19: 90-5 5)
Ie: AC-53a:
4-29: 90-5 5)
17 4 7.5
7.5
17 3 5 5 10
15
-
AGY-101
AGY-103
17 4 7.5
7.5
17 3 5 5 10
15
AGY-101
AGY-103
AGY-105
17 4 7.5
7.5
17 3 5 5 10
15
AGY-103
AGY-105
AGY-107
22
5.5
11
11
22 5 5
7.5
15
20
AGY-105
AGY-107
AGY-109
29
7.5
15
15
27
7.5
7.5
7.5
20
25
AGY-107
AGY-109
AGY-111
35
7.5
18.5
22
34
10
10
10
25
30
AGY-109
AGY-111
AGY-113
41
11
22
22
41
10
10
10
30
40
AGY-111
AGY-113
AGY-201
55
15
30
37
52
15
15
15
40
50
AGY-113
AGY-201
AGY-203
66
18.5
37
45
65
20
20
20
50
60
AGY-201
AGY-203
AGY-205
80
22
45
55
77
20
25
25
60
75
AGY-203
AGY-205
AGY-207
106
30
55
75
100
30
30
30
75
100
AGY-205
AGY-207
AGY-209
132
37
75
90
125
40
40
40
100
125
AGY-207
AGY-209
AGY-301
160
45
90
110
156
50
50
60
125
150
AGY-209
AGY-301
AGY-303
195
55
110
132
192
60
60
60
150
200
AGY-301
AGY-303
AGY-305
242
75
132
160
242
75
75
75
200
250
AGY-303
AGY-305
-
302
90
160
200
302
100
100
100
250
300
AGY-305
-
-
1)
Rated operational powers in kW as per IEC 60072-1 (primary series) corresponding to IEC current rating.
2)
Rated operational powers in hp as per UL508 corresponding to FLA current rating.
3)
The Ie and FLA rating applies for a maximum surrounding air temperature of 40oC. Above 40oC de-rate linearly by 2%
of Ie or FLA per oC to a maximum of 60oC.
4)
kW and Hp ratings applicable for AGY-101-6 to AGY-305-6 models only.
5)
For AGY-101 to AGY-209 models, a higher duty cycle F-S is possible with optional fan fitted as indicated in Fan option
table. For AGY-301 to AGY-305 models with fans fitted as standard, consult Fairford Electronics for higher duties.
Electrical Installation (continued)
Page 18
17
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
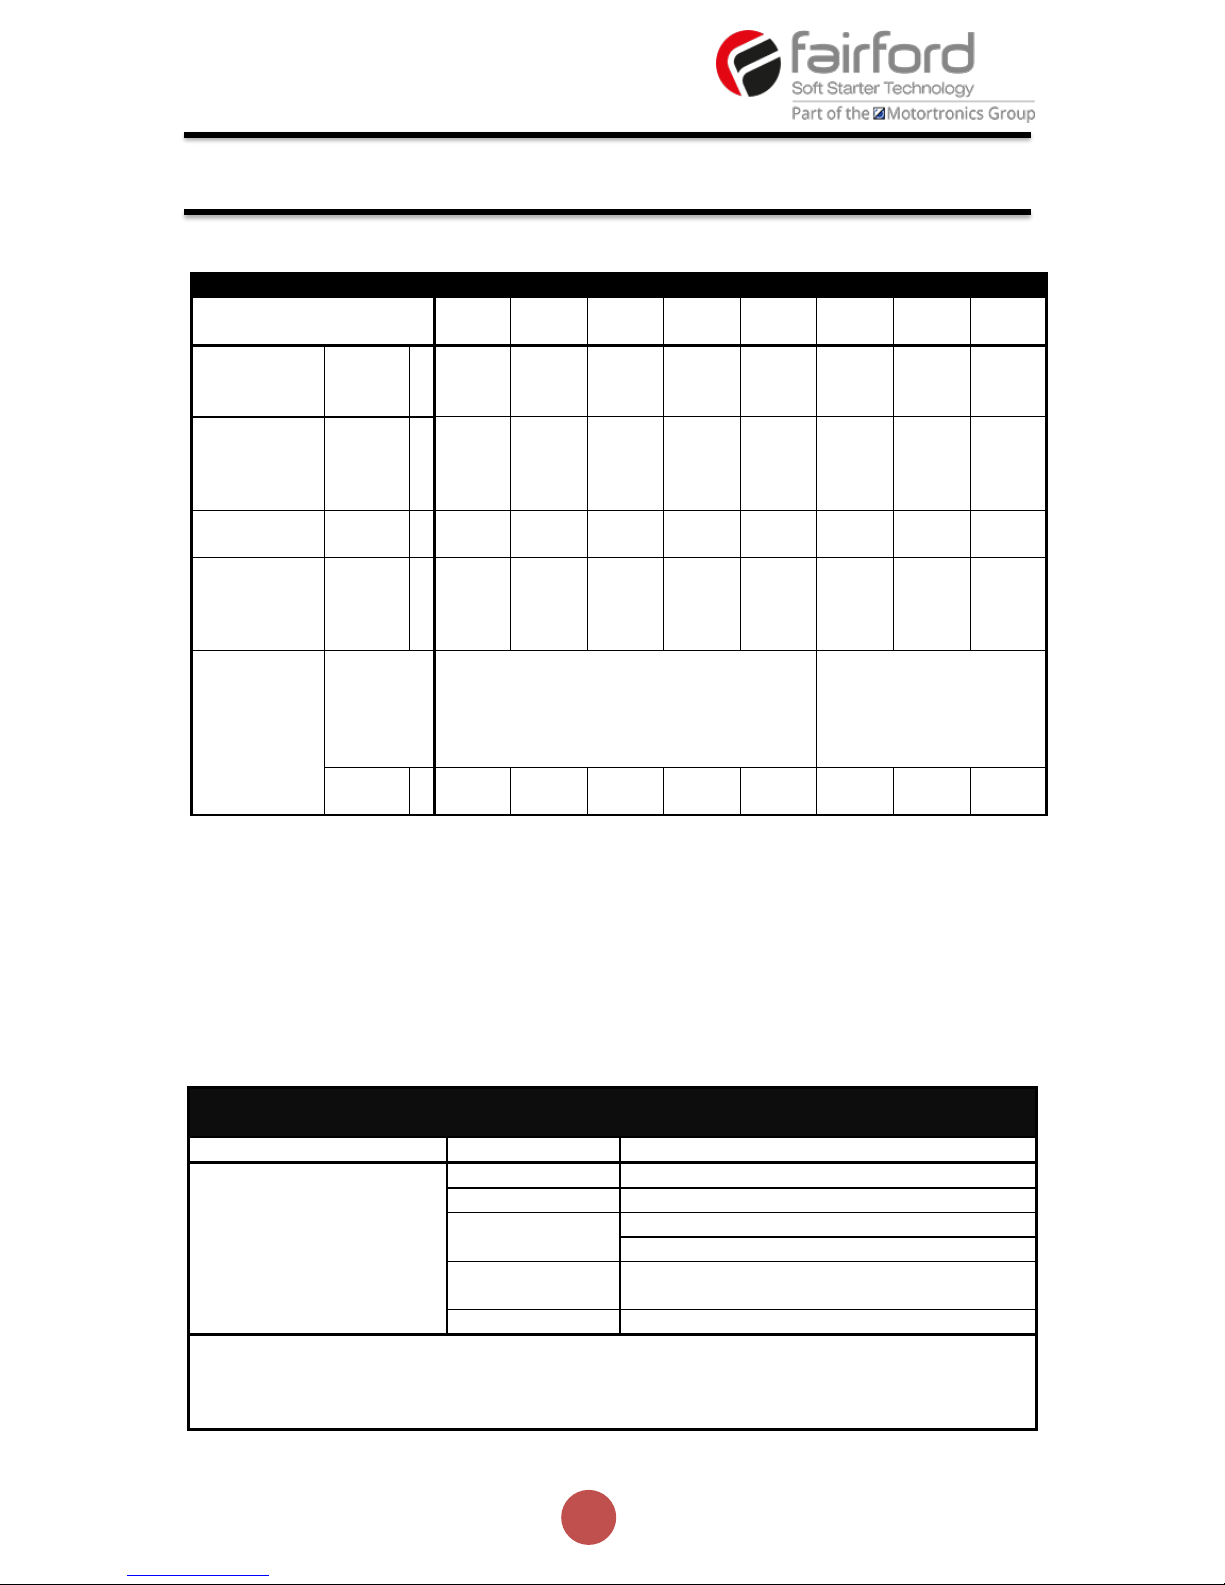
Short Circuit Protection – Agility Frame Size 2 & 3
Type designation (AGY-)
201-4
203-4
205-4
207-4
209-4
301-4
303-4
305-4
201-6
203-6
205-4
207-6
209-6
301-6
303-6
305-6
Rated
operational
current
Ie A 80
106
132
160
195
242
302
361
Rated
conditional
short circuit
current
Iq
kA
10
10
10
10
10
18
18
18
Class J timedelay fuse #1
Maximum
rating Z1
A
150
200
250
300
400
450
600
600
UL Listed
inverse-time
delay circuit
breaker #1
Maximum
rating Z2
A
250
300
350
450
500
700
800
1000
Semiconductor
fuse(class aR)
#2
Type
Mersen 6,9 URD 31__
Bussmann 170M40__
Bussmann 170M41__
Bussmann 170M42__
SIBA 20 61___
Mersen 6,9 URD 33__
Bussmann 170M60__
Bussmann 170M61__
Bussmann 170M62__
SIBA 20 63__
Fuse
rating
A
400A
400A
550A
550A
550A
800A
900A
1000A
# 1. Suitable For Use On A Circuit Capable Of Delivering Not More Than ___I
q
___ rms Symmetrical Amperes,
600Volts Maximum, When Protected by Class J time delay Fuses with a Maximum Rating of ___Z1___ or
by a Circuit Breaker with a Maximum Rating of ___Z2___.
# 2. Correctly selected semiconductor fuses can provide additional protection against damage to the agility
unit (This is sometimes referred to as type 2 co-ordination). These semiconductor fuses are
recommended to provide this increased protection.
Electromagnetic Compatibility
EMC Emission levels
EN 55011
Class A 1
EMC Immunity levels
IEC 61000-4-2
8kV/air discharge or 4kV/contact discharge
IEC 61000-4-3
10 V/m
IEC 61000-4-4
2kV/5kHz (main and power ports)
1kV/5kHz (signal ports)
IEC 61000-4-5
2kV line-to-ground
1kV line-to-line
IEC 61000-4-6
10V
1
NOTICE: This product has been designed for environment A. Use of this product in environment
B may cause unwanted electromagnetic disturbances, in which case the user may be required to
take adequate mitigation measures
Electrical Installation (continued)
Page 19
18
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
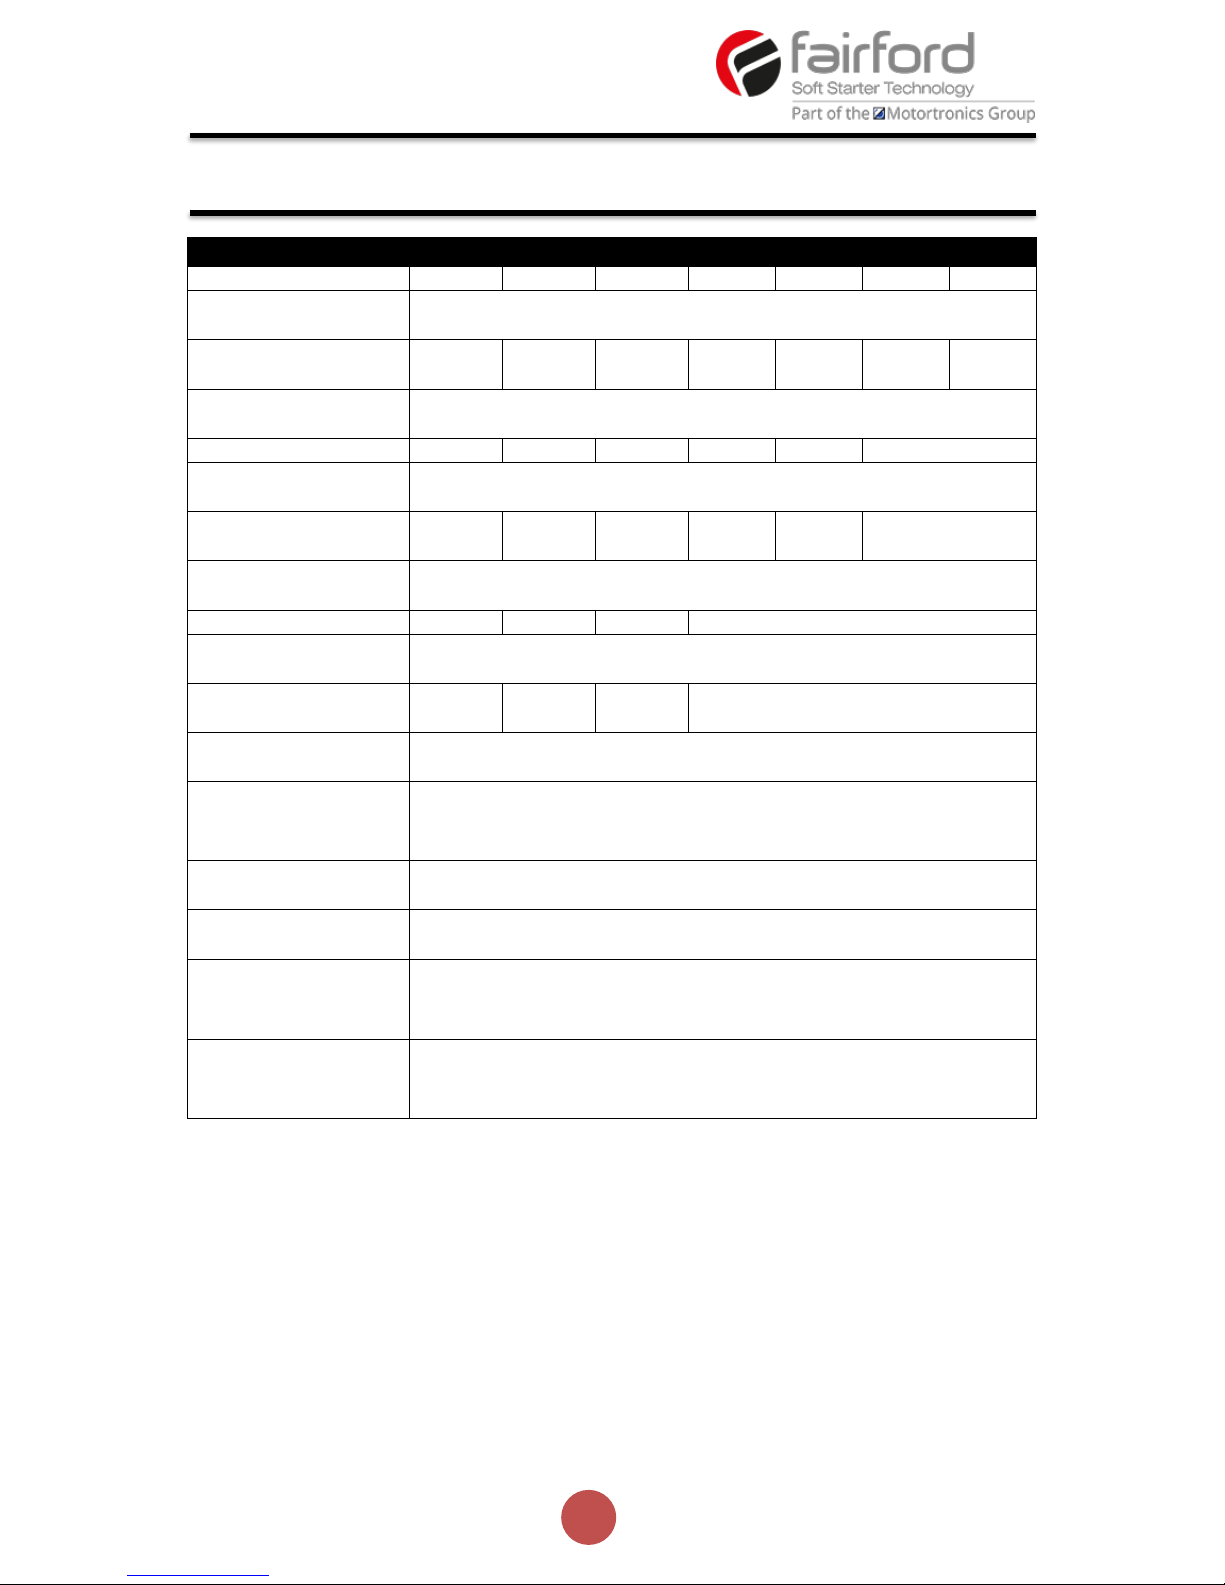
Environmental Specifications
Model (AGY-)
101
103
105
107
109
111
113
Frame Size
1
Heat output (W)
9
12
14
16
20
25
30
Weight kg [lb]
1.97 [4.20]
Model (AGY-)
201
203
205
207
209
Frame Size
2
Heat output (W)
37
49
61
74
90
Weight kg [lb]
AGY-201-AGY207 6.00 [13.23] AGY-209 6.30 [13.89]
Model (AGY-)
301
303
305
Frame Size
3
Heat output (W)
111
139
166
Weight kg [lb]
15.00 [33.10]
Ambient Operating
Temp.
-20°C [-4°F] to 40°C [104°F] ; above 40°C derate linearly by 2% of
agility Ie per °C to a maximum of 60°C (140°F)
Transportation and
Storage Temperature
-20°C to 70°C [-4°F to 158°F] continuous
Humidity
max 85% non-condensing, not exceeding 50% @ 40°C [104°F]
Maximum Altitude
1,000m [3281ft] ; above 1000m derate by 1% of agility Ie per 100m
(328ft) to a maximum altitude of 2,000m (6562ft)
Environmental Rating
Main Circuit: IP00 (IP20 with optional finger guards);
Control Circuit: IP20; No corrosive gases permitted
Electrical Installation (continued)
Page 20
19
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
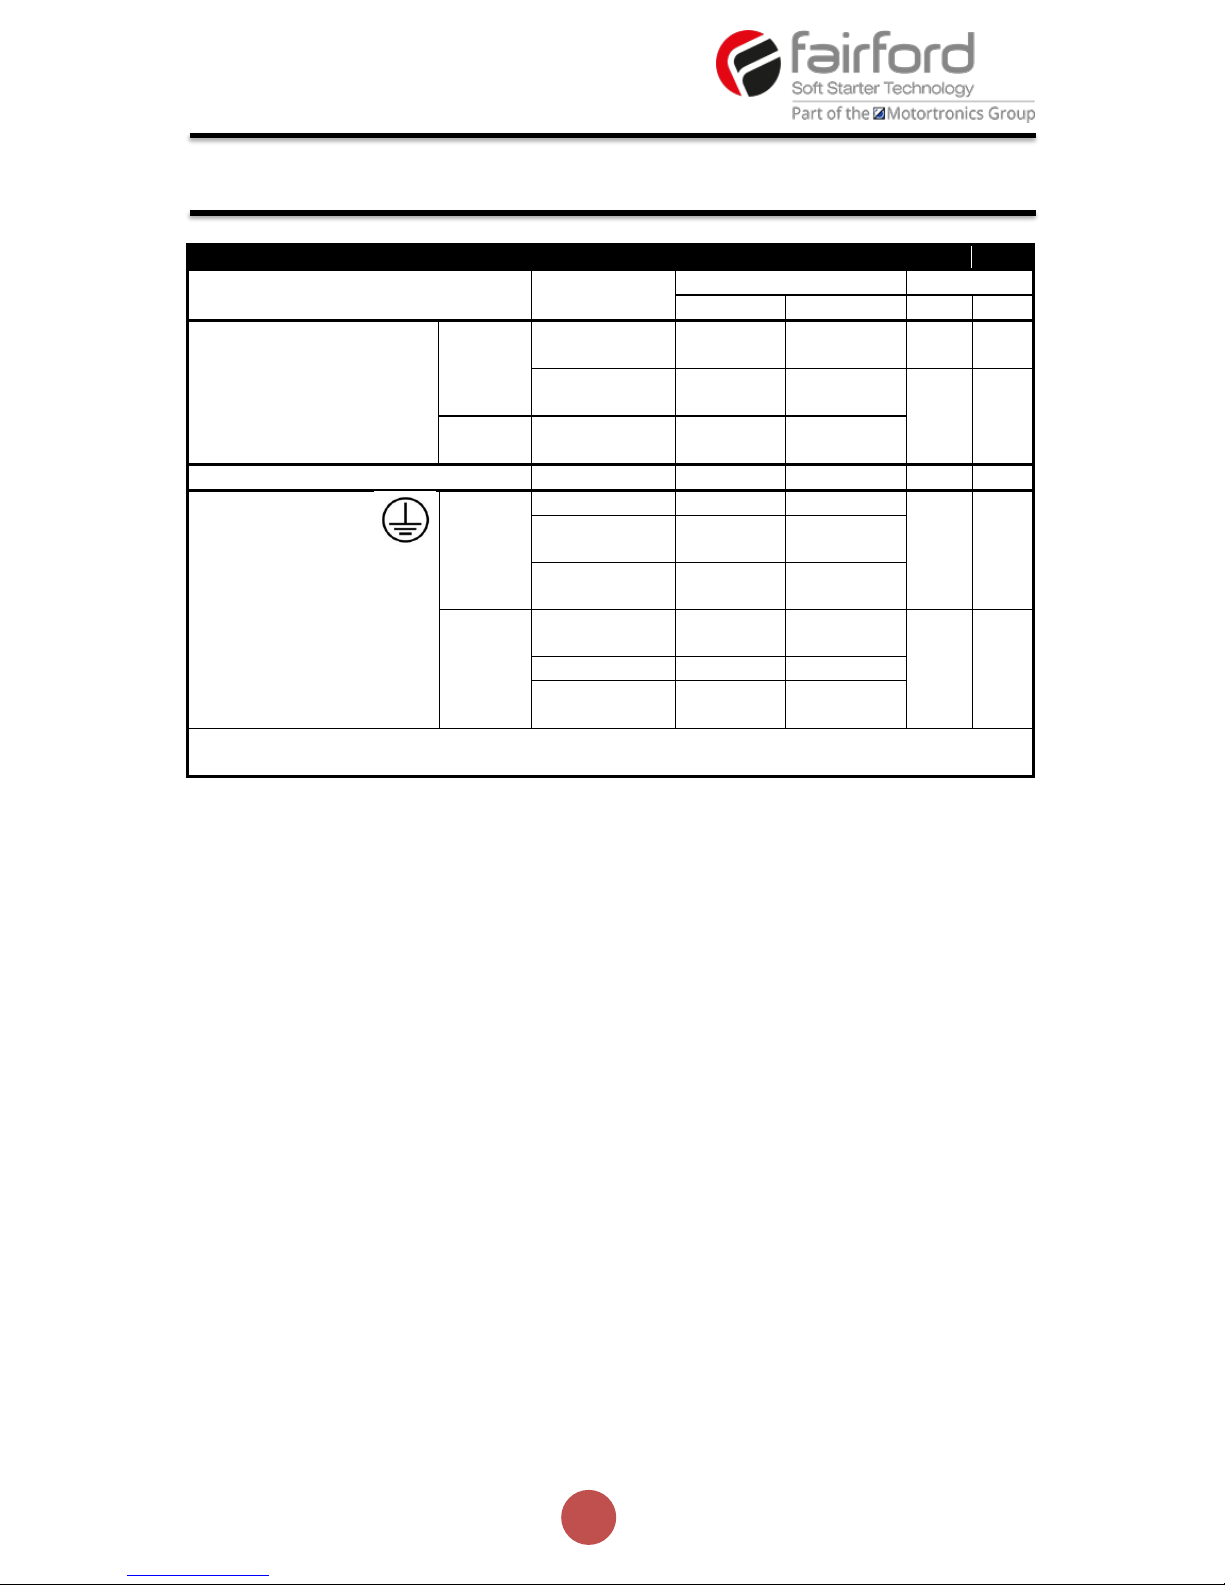
Wire Sizes and Torques
Terminal
Models
Wire/Busbar Size
Torque
Metric
Imperial
Nm
Ib-in
Main Terminals
Terminal
AGY-101 to AGY113
2.5 - 70mm2
12- 2/0AWG
9
80
Cu STR 75oC only
AGY-201 to AGY209
4 - 185mm2
12 – 350MCM
14
123 M10 bolt
AGY-301 to AGY305
2 x 95mm2
2 x 2/0AWG
Control terminals
All models
0.2–1.5mm2
24-16AWG
0.5
4.5
Protective Earth 1)
M6 screw
AGY-101
≥ 4mm2
≥ 12AWG
8
70
Cu only
AGY-103 to AGY111
≥ 6mm2
≥ 10AWG
AGY-113 to AGY203
≥ 10mm2
≥ 8AWG
M8 screw
AGY-205 to AGY209
≥ 16mm2
≥ 6AWG
12
105
AGY-301
≥ 25mm2
≥ 4AWG
AGY-303 to AGY305
≥ 35mm2
≥ 3AWG
1)
Protective Earth wire size based on bonding conductor requirements of UL508 Table 6.4 and UL508A
Table 15.1.
Electrical Installation (continued)
Page 21
20
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
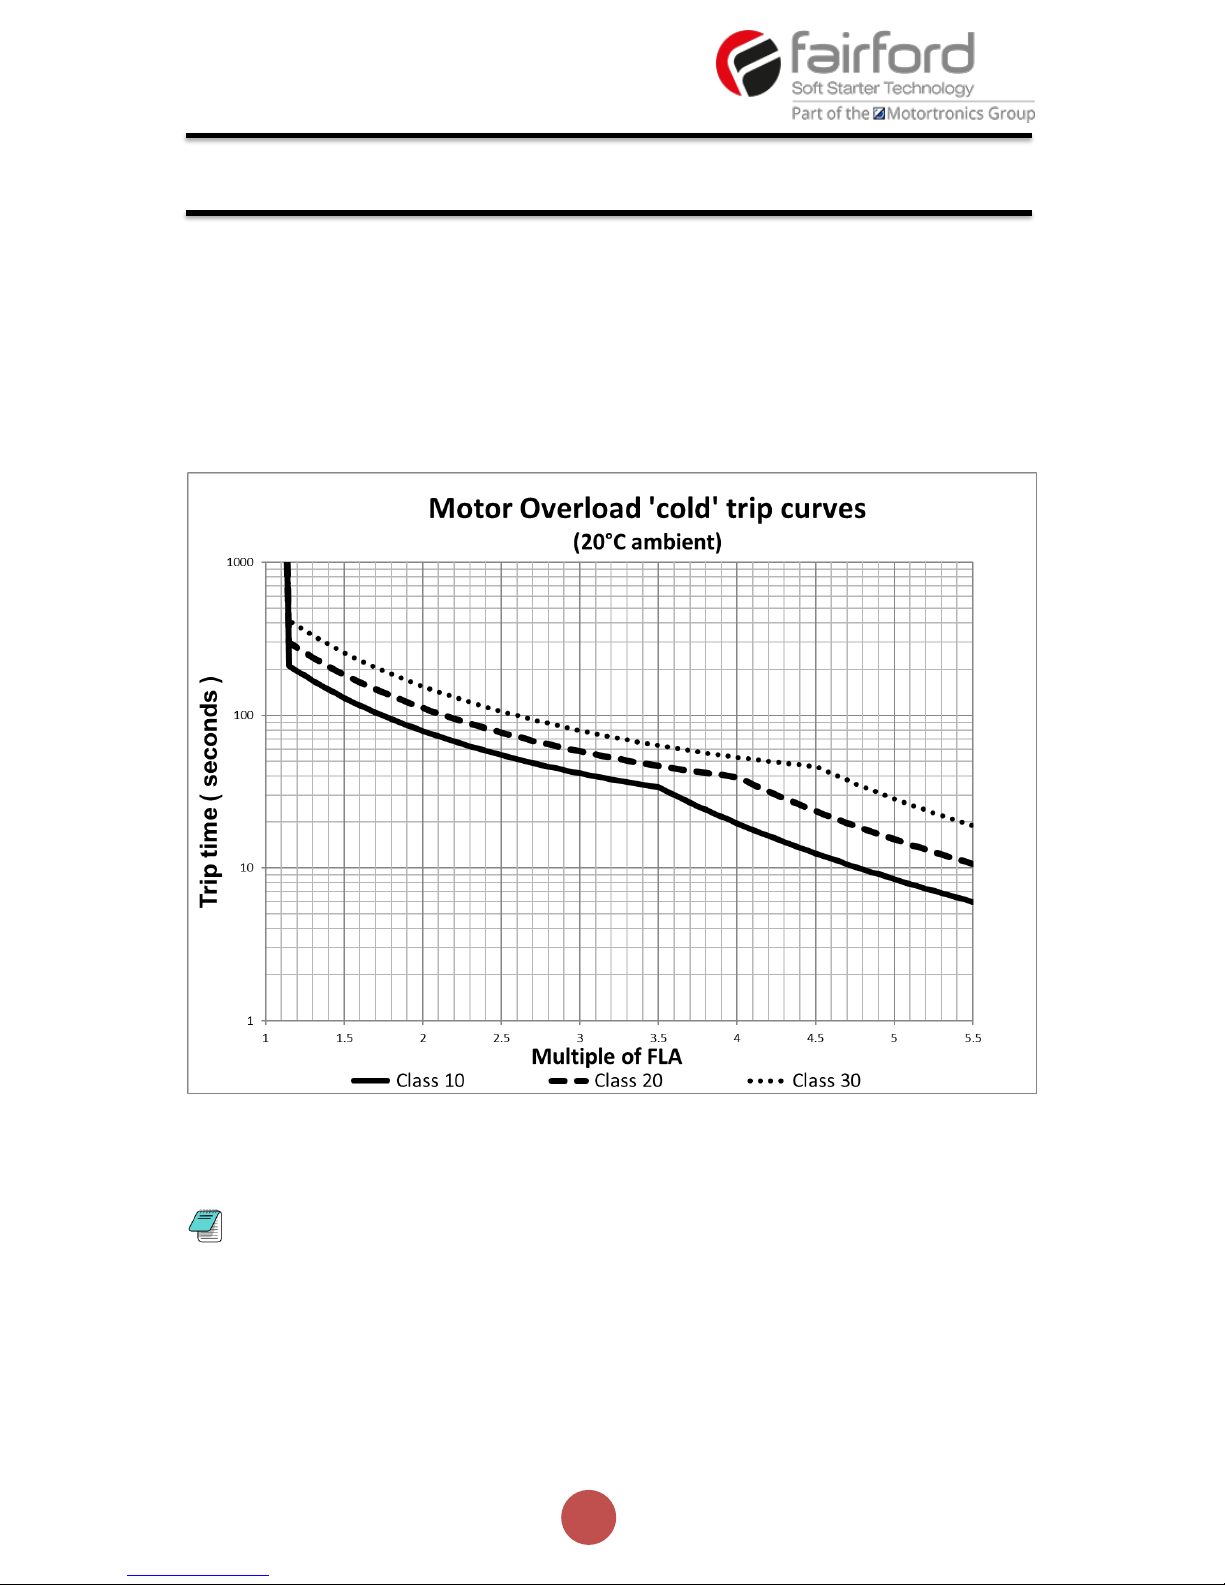
Motor Overload Protection
agilityTM provides full motor overload protection, configurable through the user interface.
Overload trip settings are determined by the Motor Current setting and the Trip Class setting.
Trip class choices are Class 10, Class 20, and Class 30. The agilityTM soft starters are protected
using full I2T motor overload with memory. See Appendix 1 for sizing guide.
Please note: When the overload has tripped, there is a forced cooling time to allow the
overload to recover before the next start.
The ‘warm’ trip times are 50% of the ‘cold’ trip time
Electrical Installation (continued)
Page 22
21
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
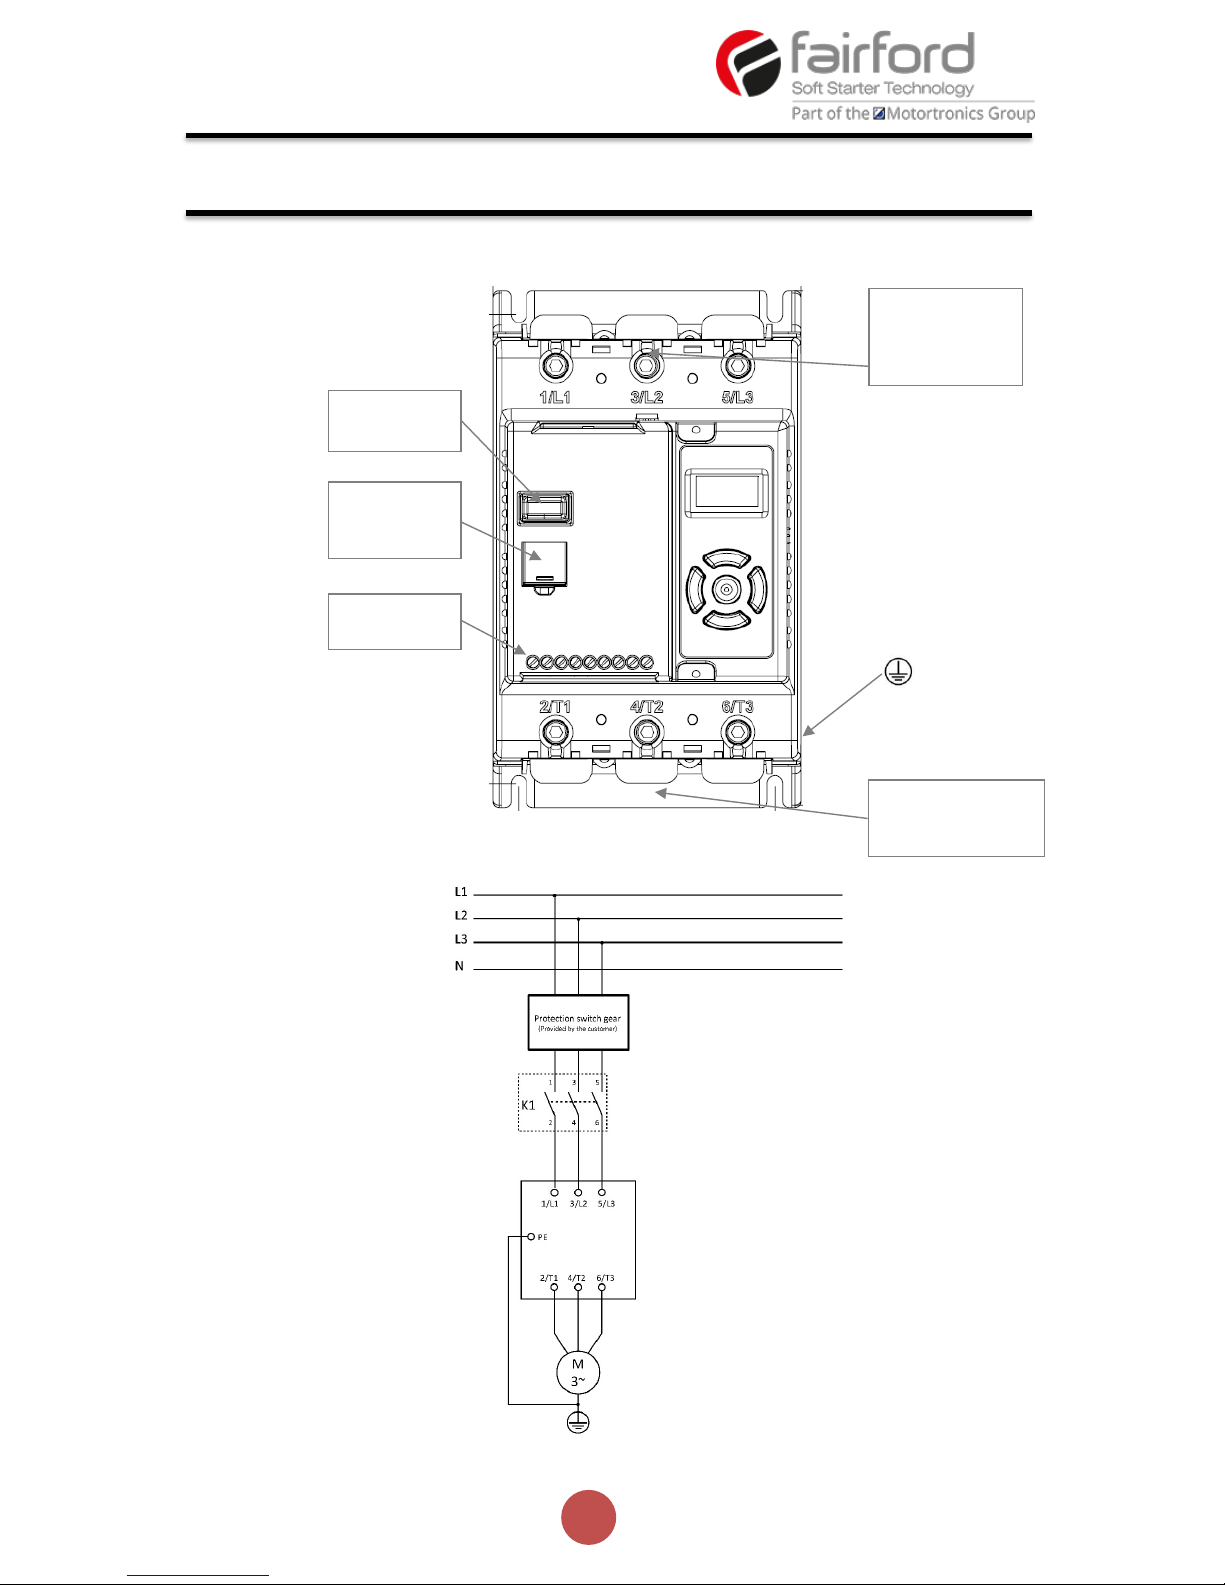
Electrical Connections
Main Circuit Wiring Diagram
Electrical Installation (continued)
3-Phase Electrical
Supply
Connections
(L1, L2, L3)
RJ45
connector
(Modbus RTU)
USB
Connector
Control
Terminals
AC Induction Motor
Connections
(T1, T2, T3)
Page 23
22
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
2/T1 4/T2 6/T3
1/L1 3/L2 5/L3
X
X
M
1
Protection Switch Gear
(Provided by customer)
L
N
PE
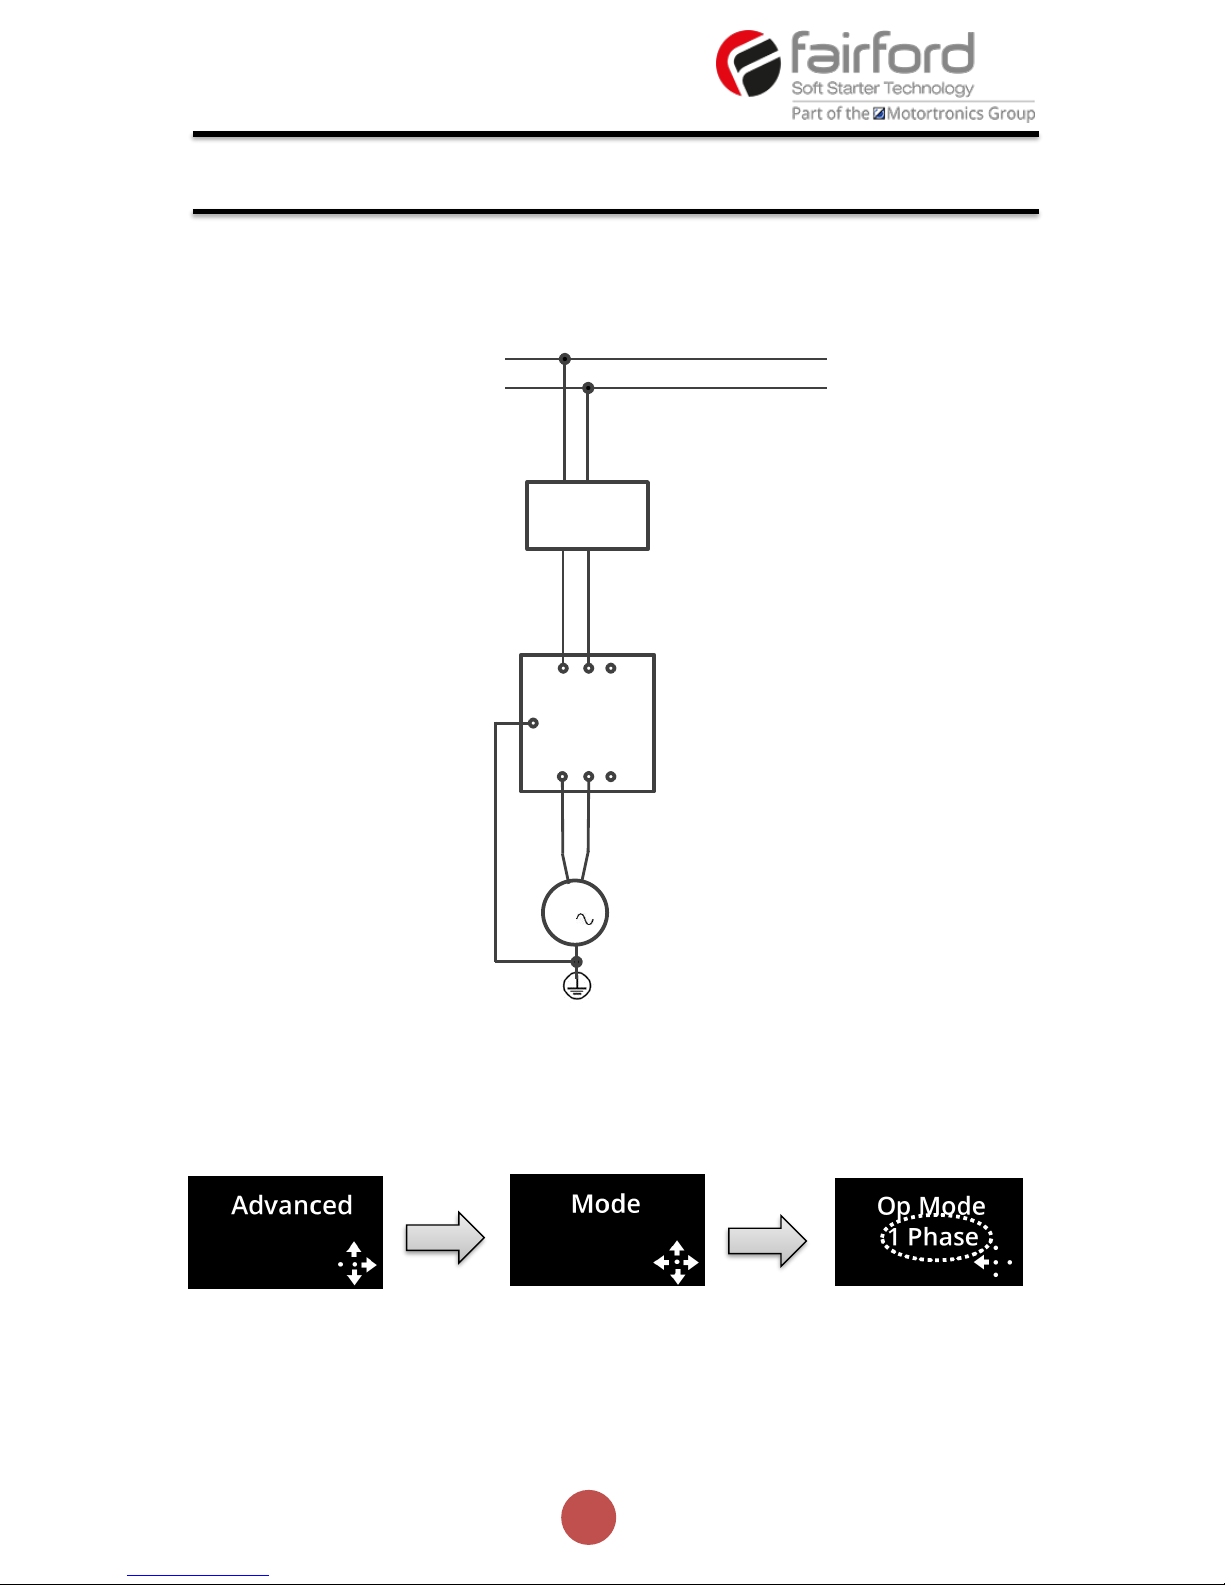
Single Phase Operation
Agility soft starts may be operated with a single-phase supply and motor. The base
rating of the unit is unchanged.
Electrical Connection
Electrical Installation (continued)
For single phase operation the mode of the soft start must be set correctly in the Advanced
menu:
Page 24
23
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
24V
COM
0V
13
D1
14
D2
22
21
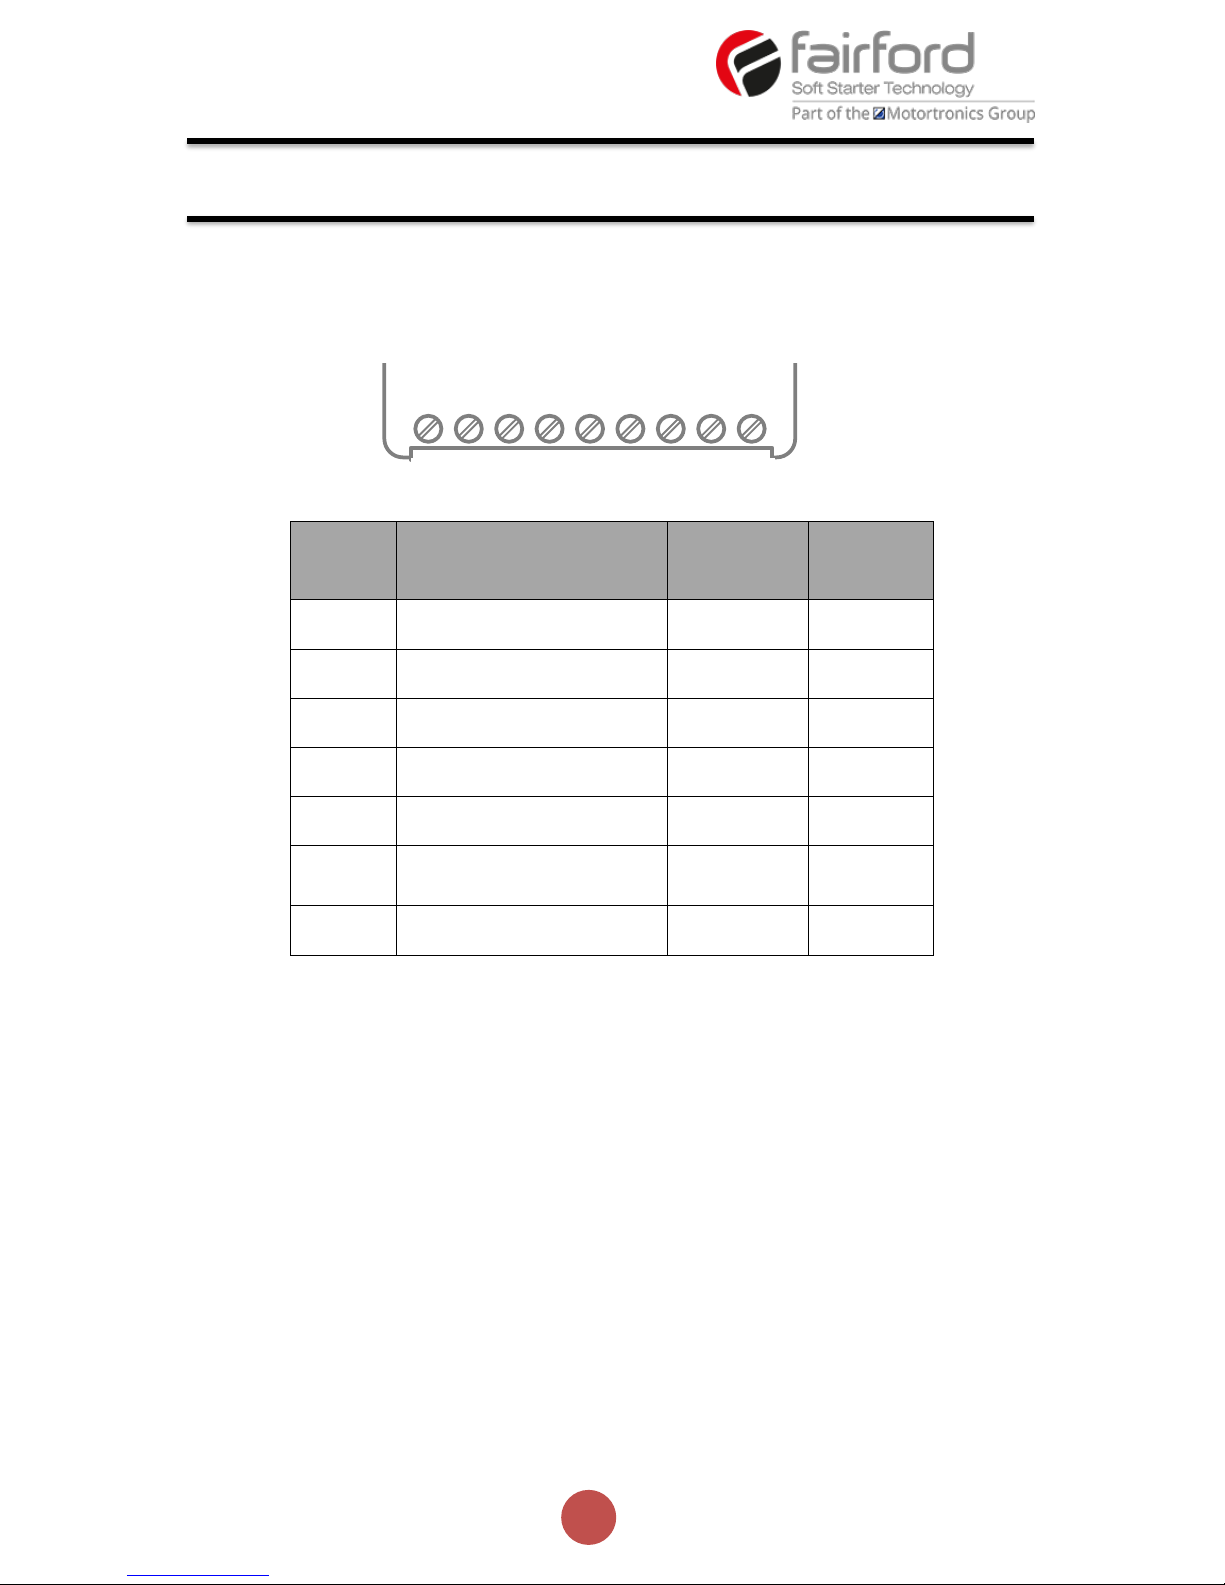
Control Terminal Connection
Control Terminal Functions
#1 24V dc Specification: 24V 10VA, residual ripple < 100Mv, spikes/switching peaks < 240mv,
#2 The voltage applied to the digital inputs D1 and D2 must not exceed 24V dc
#3 230Vac, 1A, AC15. 30Vdc, 0.5A resistive
Digital Input 2 (D2) Selectable Functions
Different functions may be assigned to Digital Input 2 in the I/O menu. Available assignments
are:
Reset
Hold Start Ramp
Enable
Fire Mode (In Fire Mode all trips are disabled)
Digital Output 21/22 Selectable Functions
The output may be mapped to Fault or Top-of-Ramp indication
Terminal
Description
Function
Selectable
Note
24Vdc
Control Supply +Us
No
#1
0V
Control Supply -Us
No COM
Digital Inputs Common
No D1
Digital Input 1
No
#2
D2
Digital Input 2
Yes
#2
13/14
Main Contactor Control
(Run Relay)
No
#3
21/22
Fault Relay
Yes
#3
Electrical Installation (continued)
Page 25
24
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
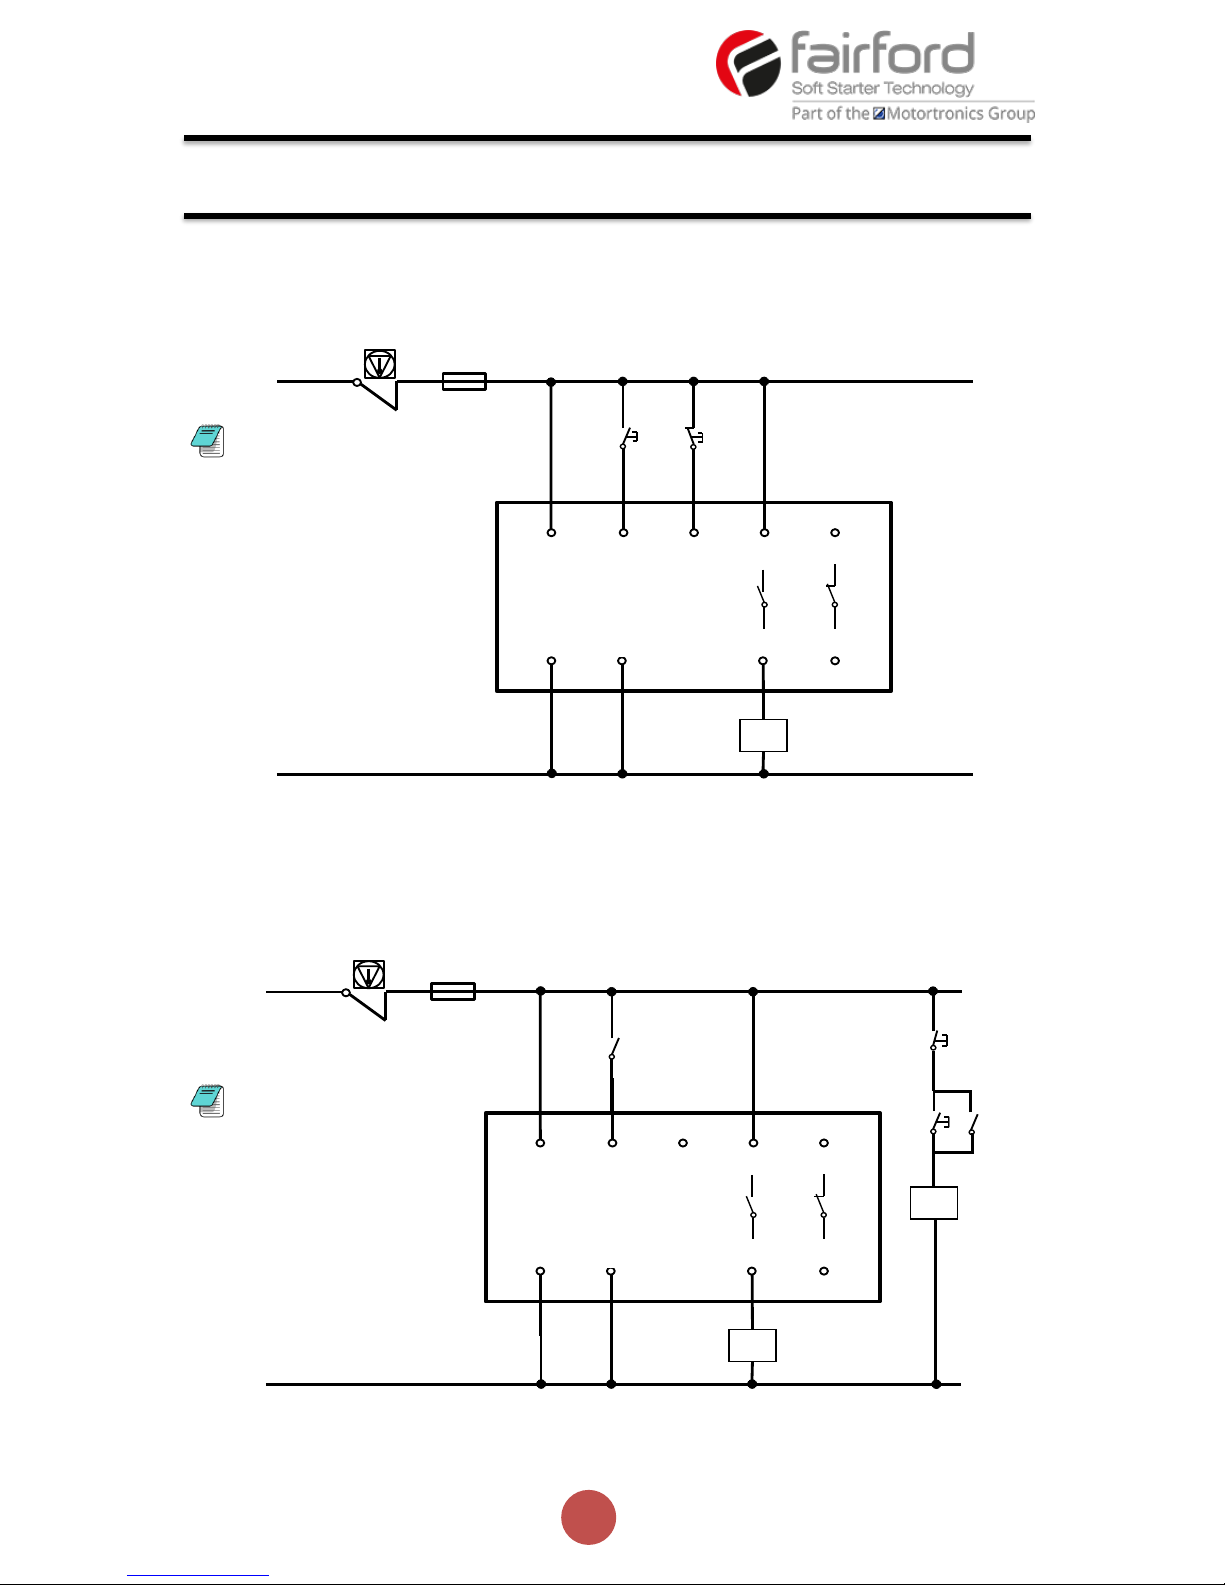
3-Wire Control Circuit Wiring Diagram
2-Wire Control Wiring Diagram
Note: 110 – 230V control supply
possible with optional control
supply module (AGY-020 amd
AGY-021)
Electrical Installation (continued)
K1
0V
Start
Stop
24V
D1
D2
13
COM
14
21
22
FU1
24Vdc
K2.2
K1
0V
24V
D1
D2
13
0V
COM
14
21
22
FU1
24Vdc
Note: 110 – 230V control supply
possible with optional control
supply module (AGY-020 and
AGY-021)
K2.1
K2
Start
Stop
Page 26
25
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Display and Controls
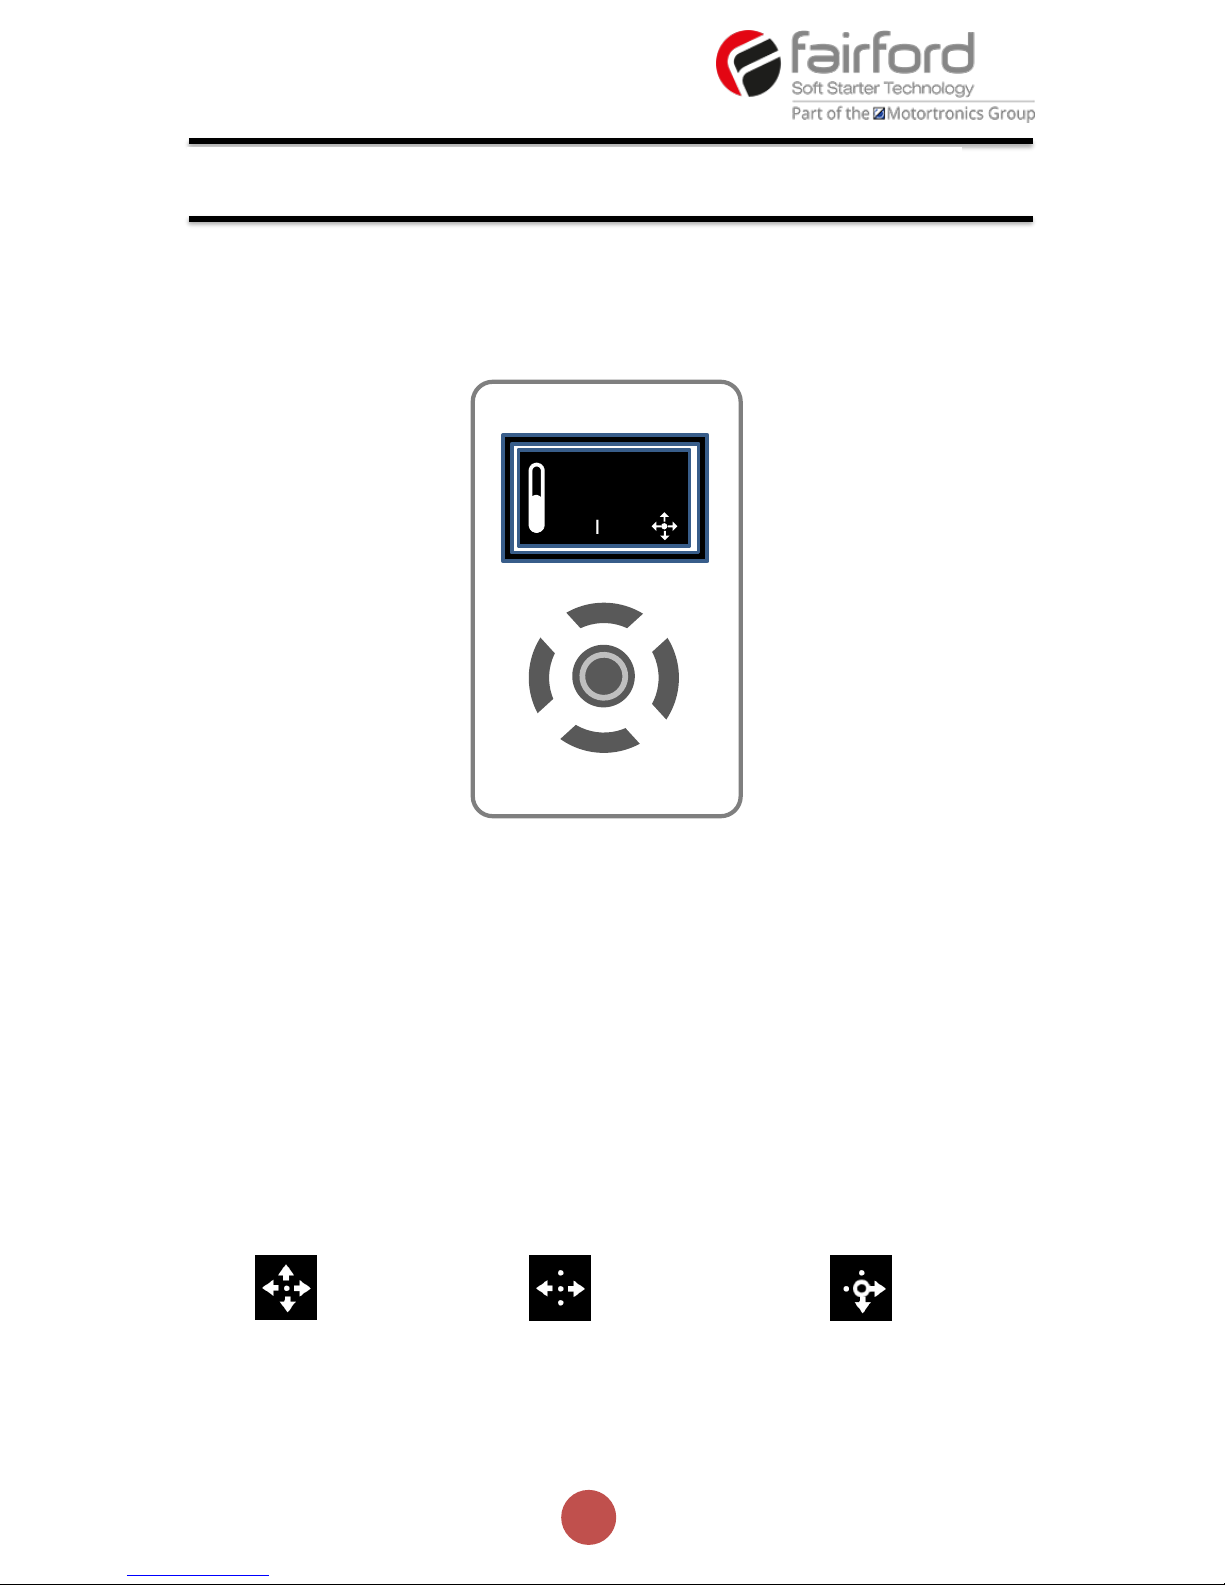
Keypad Guidance Examples
All keys active Left & Right keys active Right, Down & Centre keys active
Note: A flashing centre button indicates that a menu item may be selected or saved.
Local
Status messages
Instantaneous motor current
Control scheme: Local, Control terminal, Modbus RTU
Motor overload level; 0 to 100%
Keypad guidance wizard: Displays which keys are valid for specific menu items
Status LED (incorporated into centre button) Green/Red
READY
32A
Local
Control keypad
Configuration and Parameters (continued)
Page 27

26
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Operation - Local Motor Start
Example Navigation Method
Auto Application Setup
Configuration and Parameters (continued)
Quick Return to Status Screen
(Centre button to adjust)
Page 28
27
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Setup Procedure (Auto App)
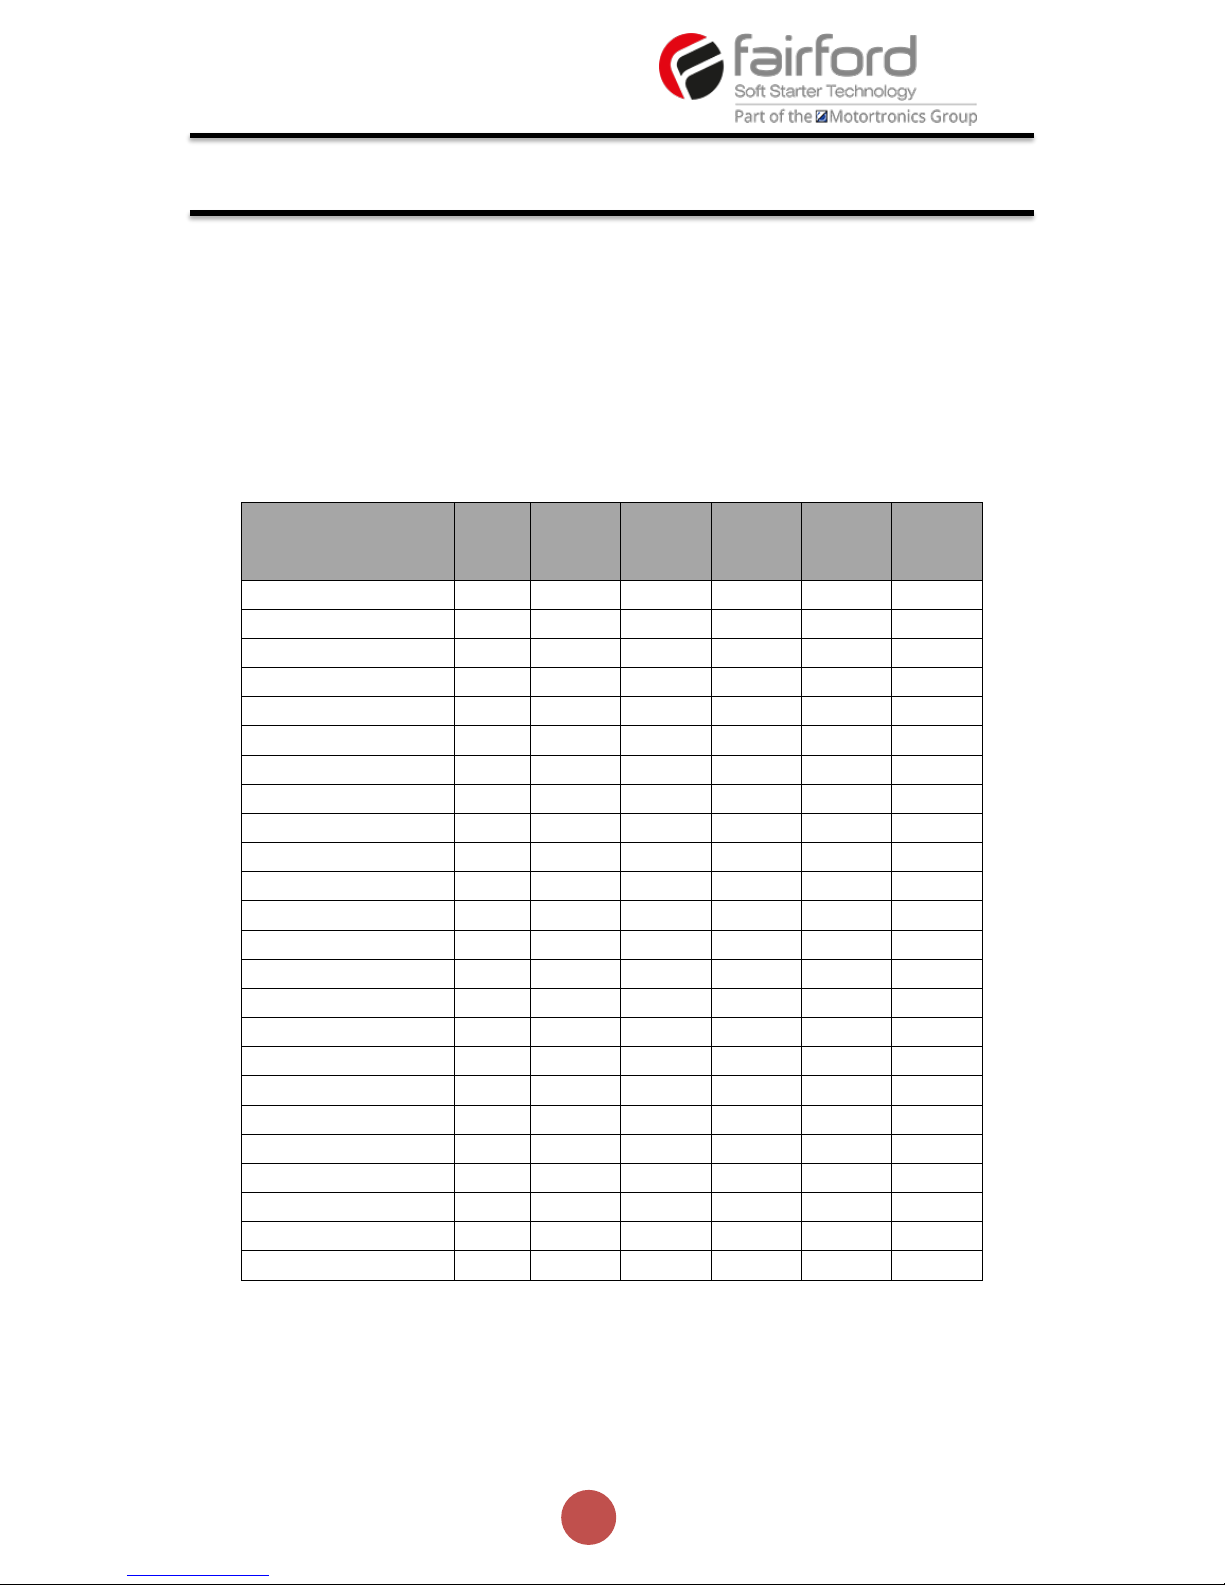
Allows the user to change all of the parameters at once to settings that are typical for general applications.
One or more parameters as can be adjusted to fine tune the settings for your specific application.
Setup by Individual Parameter Settings (Advanced)
Allows the user to change the parameter settings one at a time.
Auto Application Setup Parameter Settings
Initial
Volts
Start
Time
Stop
Time
Trip
Class
Current
Limit
Current
Limit
Time
Unit
% s s
-
*FLC
s
Default
20%
10 0 10
3.5
30
Heavy
40%
10 0 20 4 40
Agitator
30%
10 0 10
3.5
25
Compressor 1
40%
15 0 20
3.5
25
Compressor 2
35% 7 0
10
3.5
25
Conveyor Loaded
10%
10 7 20
5.5
30
Conveyor Unloaded
10%
10 7 10
3.5
30
Crusher
40%
10 0 30
3.5
60
Fan High Inertia
40%
10 0 30
3.5
60
Fan Low Inertia
30%
15 0 10
3.5
30
Grinder
40%
10 0 20
3.5
40
Mill
40%
10 0 20
3.5
40
Mixer
10%
10 0 20 4 25
Moulding M/C
10%
10 0 10
4.5
25
Press Flywheel
40%
10 0 20
3.5
40
Pump 1
10%
10
60
10
3.5
25
Pump 2
10%
10
60
20
3.5
25
PumpJack
40%
10 0 20
3.5
40
SawBand
10%
10 0 10
3.5
25
SawCircular
40%
10 0 20
3.5
40
Screen Vibrating
40%
10 0 20
4.5
40
Shredder
40%
10 0 30
3.5
60
Wood Chipper
40%
10 0 30
3.5
60
Compressor 1 = Centrifugal, Reciprocating, Rotary Screw
Compressor 2 = Rotary Vane, Scroll
Pump 1 = Submersible: Centrifugal, Rotodynamic
Pump 2 = Positive Displacement: Reciprocating, Rotary
Configuration and Parameters (continued)
Page 29
28
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
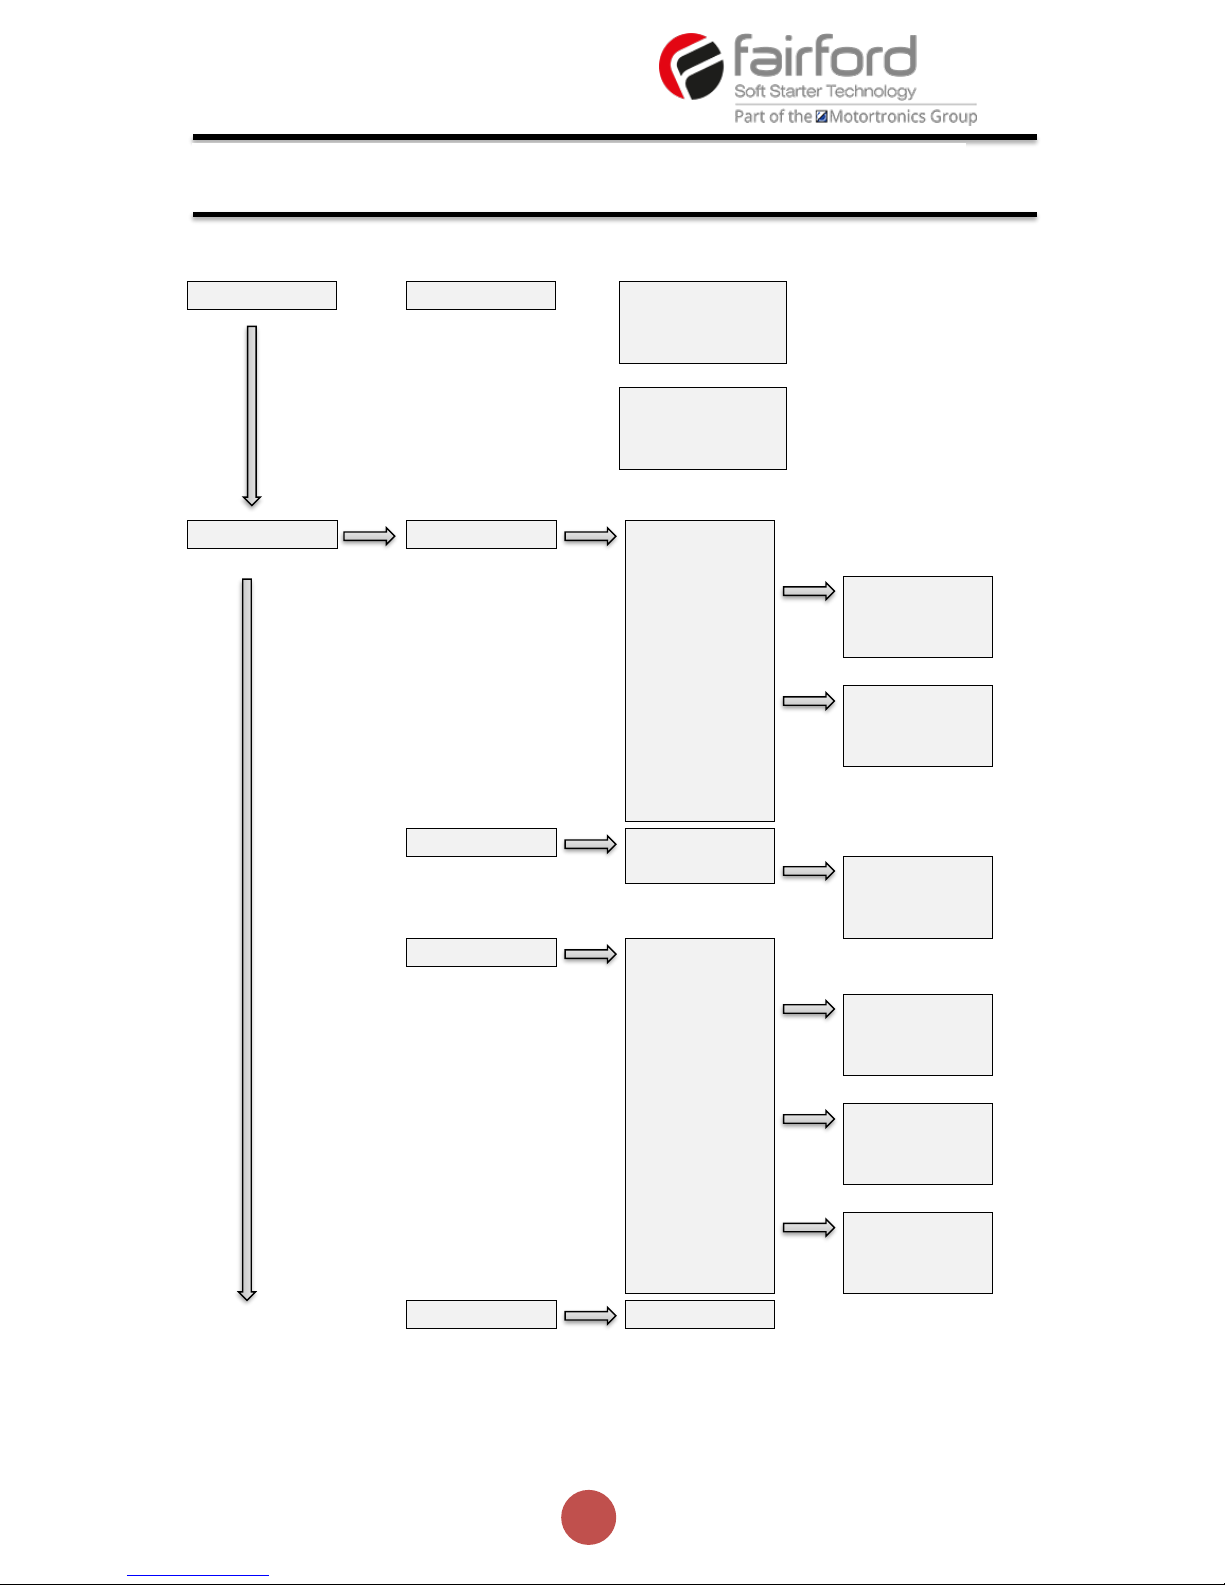
Level 0
Level 1
Level 2
Level 3
Monitor
I rms
I1 rms
I2 rms
I3 rms
Overload
Rotation
HS Temp
TempUnit
Delay Angle
Frequency
RX Bytes
TX Bytes
RX Errors
TX Errors
StartsHr
Initial Temp
Pending
Exceeded
Delay
Attemps
Trip Free
Trip Event
Auto Setup
Application
Default
Heavy
Agitator
Compressor 1
Compressor 2
Conveyor Loaded
Conveyor
Unloaded
Crusher
Fan High Inertia
Fan Low Inertia
Grinder
Mill
Mixer
Moulding M/C
Press Flywheel
Pump 1
Pump 2
PumpJack
Saw-Band
Saw-Circular
Local
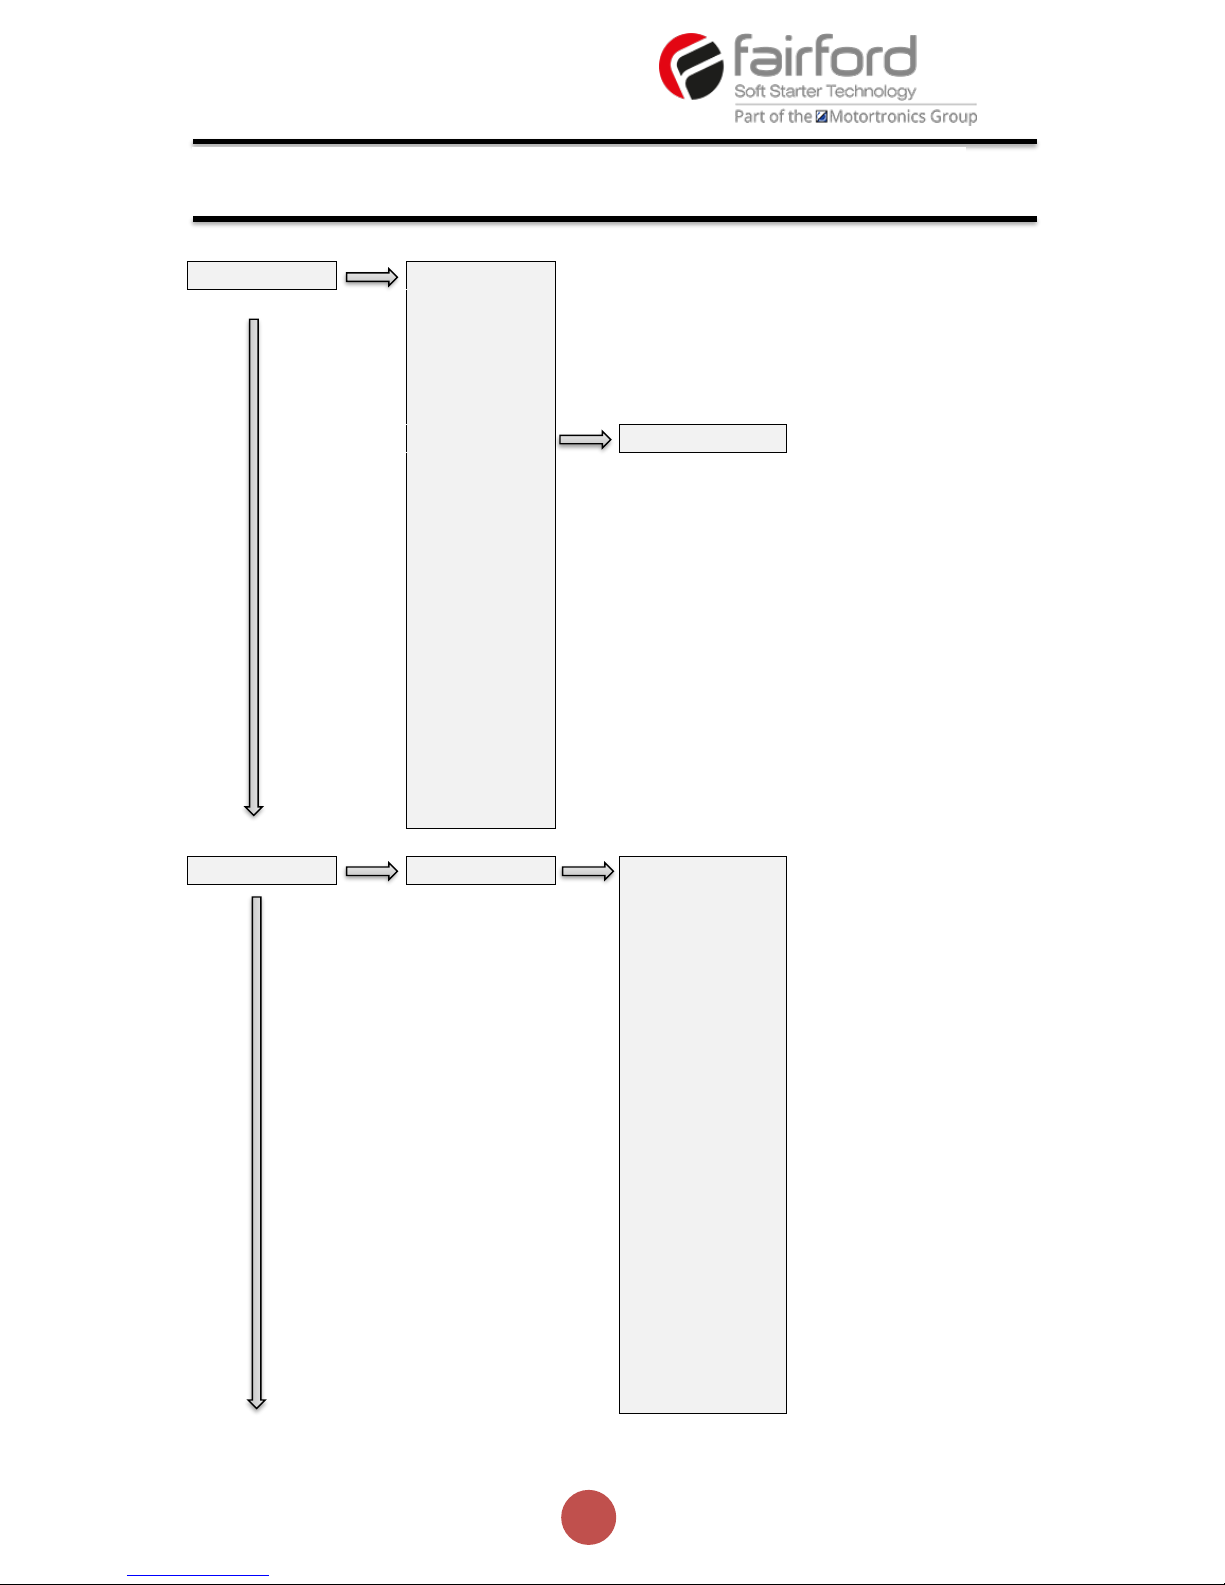
Menu Structure
Page 30
29
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
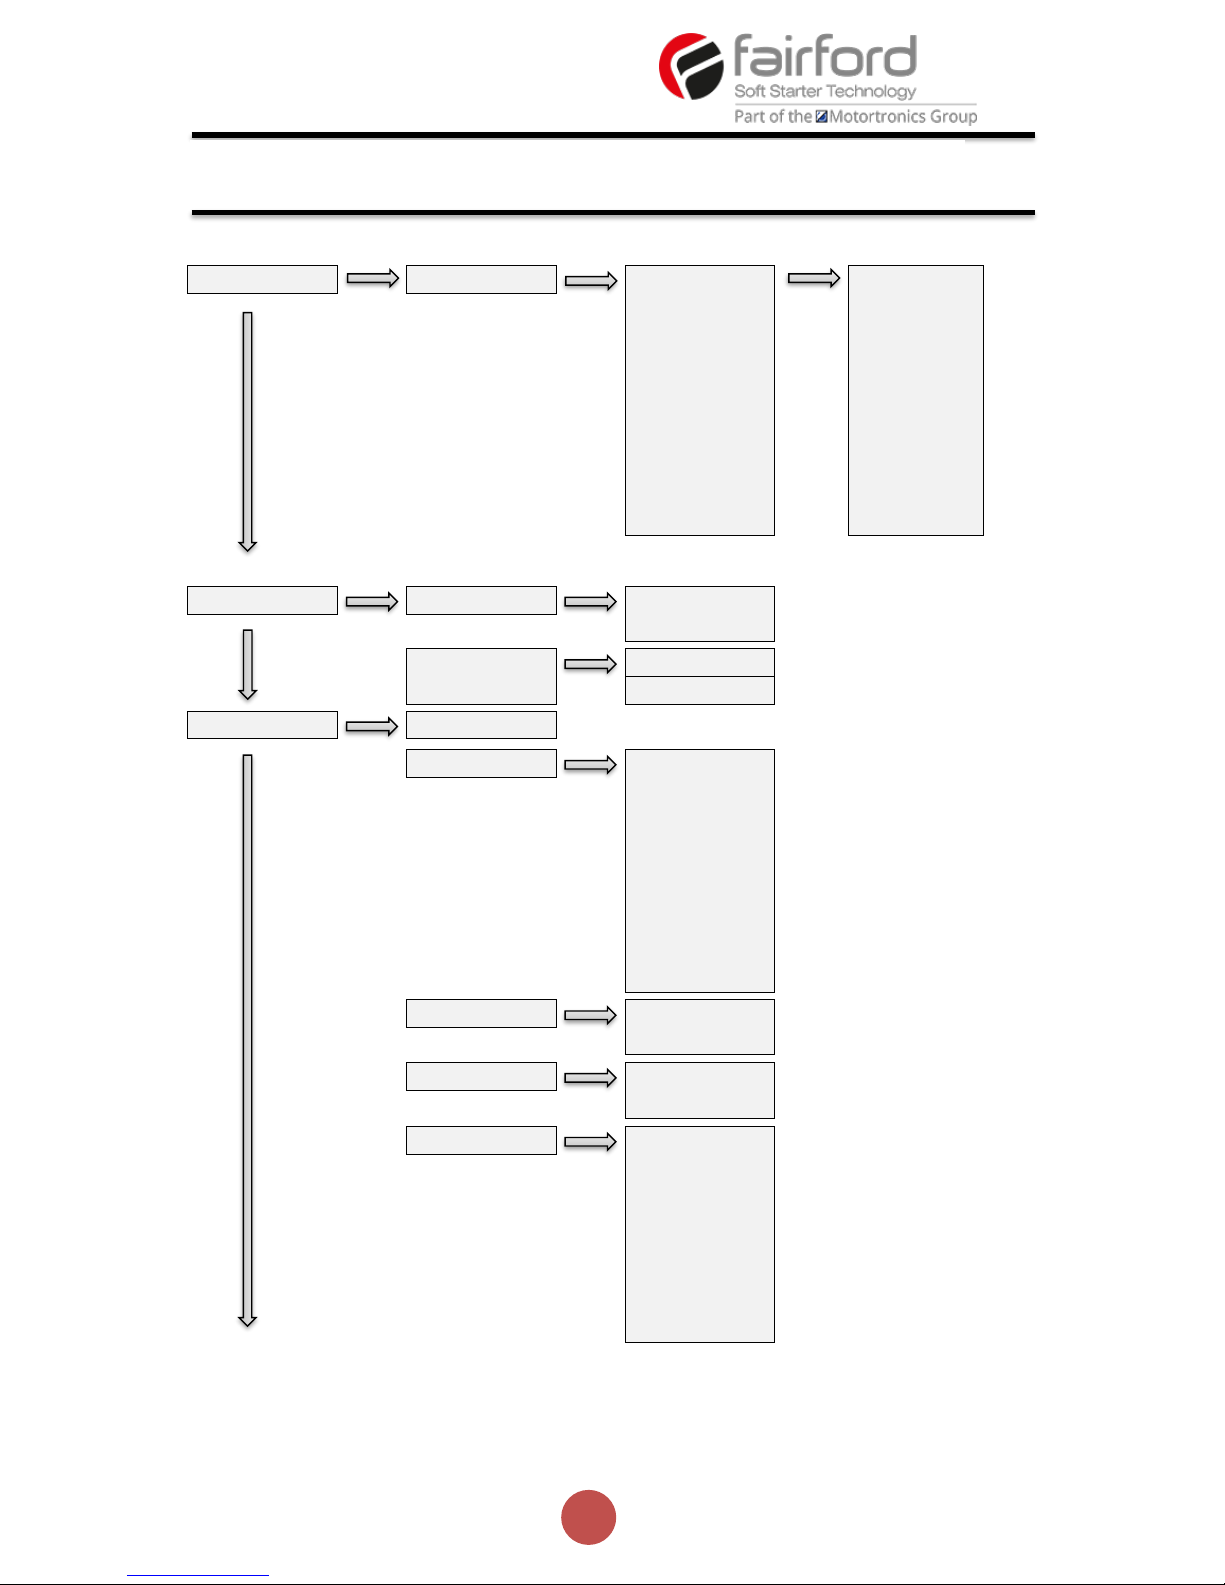
Advanced
Start Param
Start Time
Initial Volts
I Limit
I Limit Start
Limit Amps
Limit Time
Kick Start
Kick Start
Kick Time
Kick Level
Start Delay
Stop Param
Stop Time
Limit
I Limit Stop
Limit Amps
Limit Time
Protection
Motor Amps
Overload
Overload
Trip Class
Ovld Amps
Shearpin
Shearpin
Shear Amps
Shear TIme
Low Amps
I Low
I Low Amps
I Low Time
Mode
Op Mode
Level 0
Level 1
Level 2
Level 3
Auto Setup
Application
Screen Vibrating
Shredder
Woodchipper
Motor Amps
Cntrl Mode
Cntrl Funct
Menu Structure (continued)
Page 31

30
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
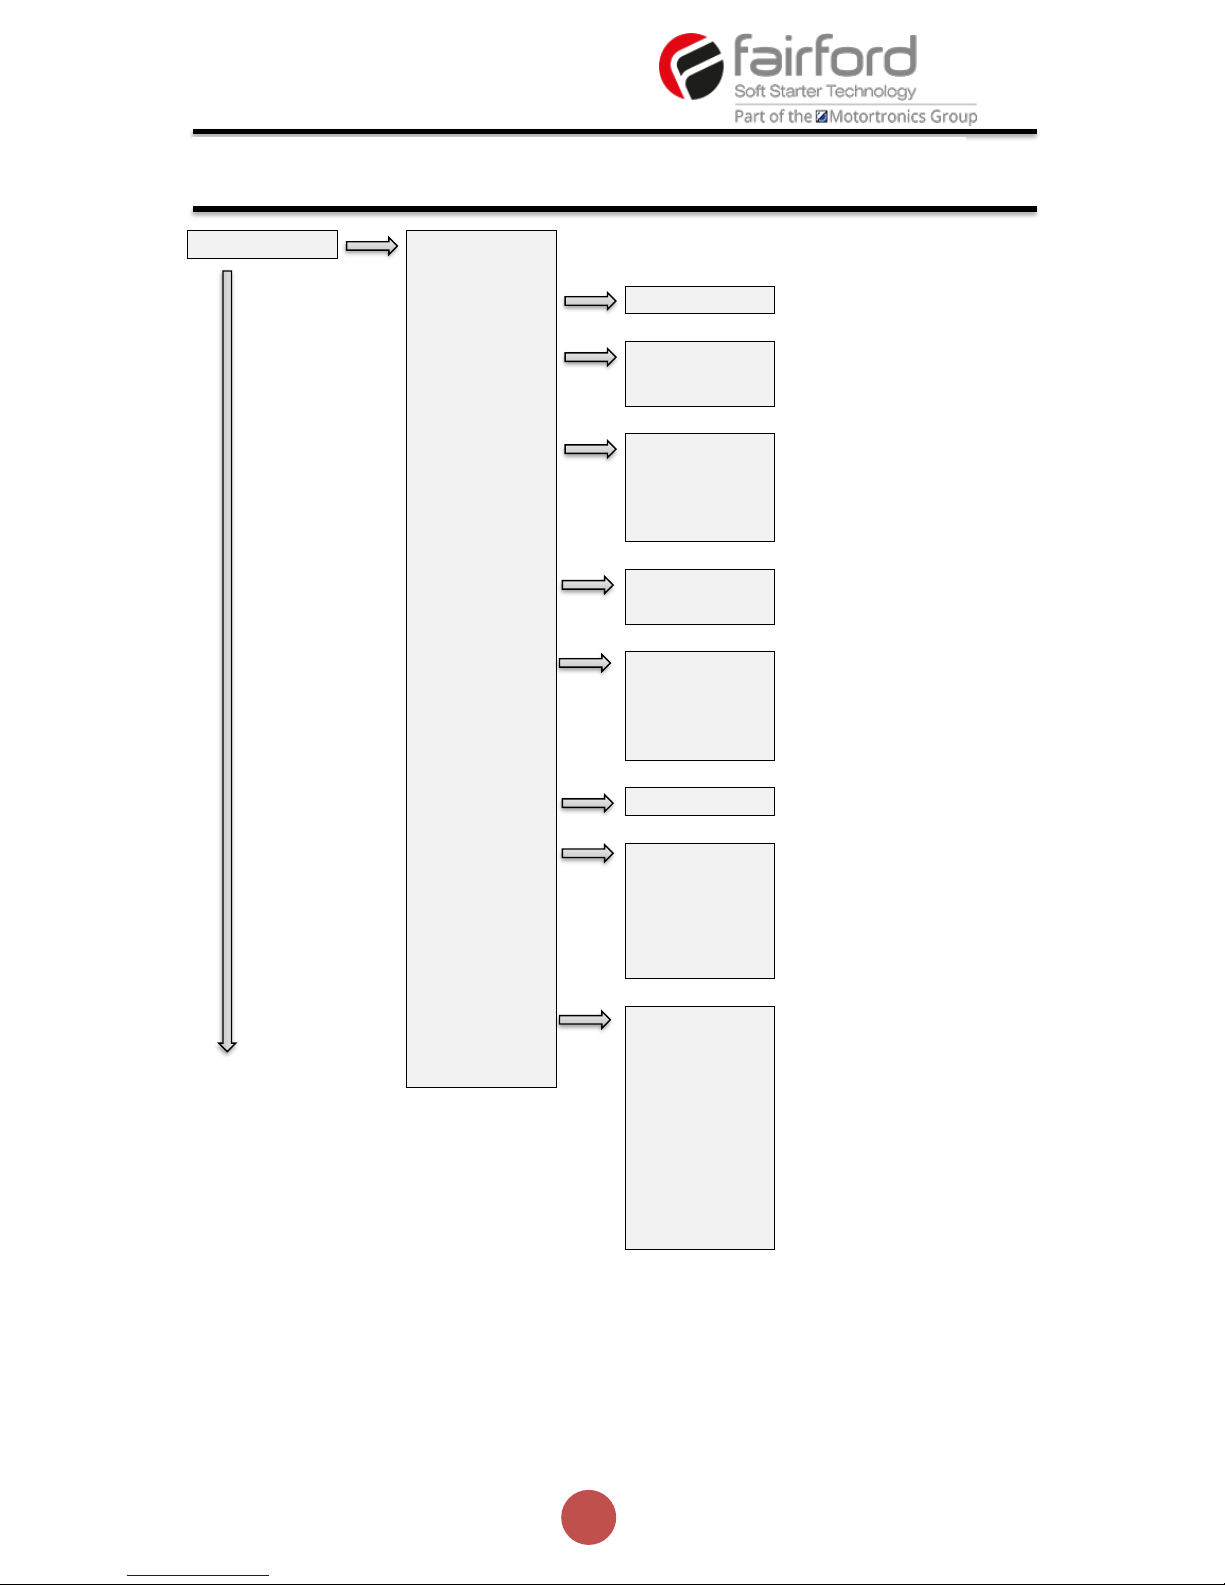
Level 0
Level 1
Level 2
Level 3
Advanced
Trips
Trip Sens
Phase Loss
Sensor Loss
Ph / SCR
Hz HighLow
I Low
I Limit Start
I Limit Stop
Overload
Shearpin
Comms
Remote
CT Fault
L1L2L3
L1L3L2
Operation 1
Operation 2
I Standby
Auto Reset
Auto Reset
Reset Delay
Reset Attempts
Trip Free Time
Reset Trips
Phase Loss
Thermal
SCR Fire
Ph/SCR
Hz High Low
Uc Low
SCR Sen
Fan
I Low
I Limit
Overload
Shearpin
External
Comms
Bypass
Control
Rotation
CT Fault
Menu Structure (continued)
Page 32
31
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
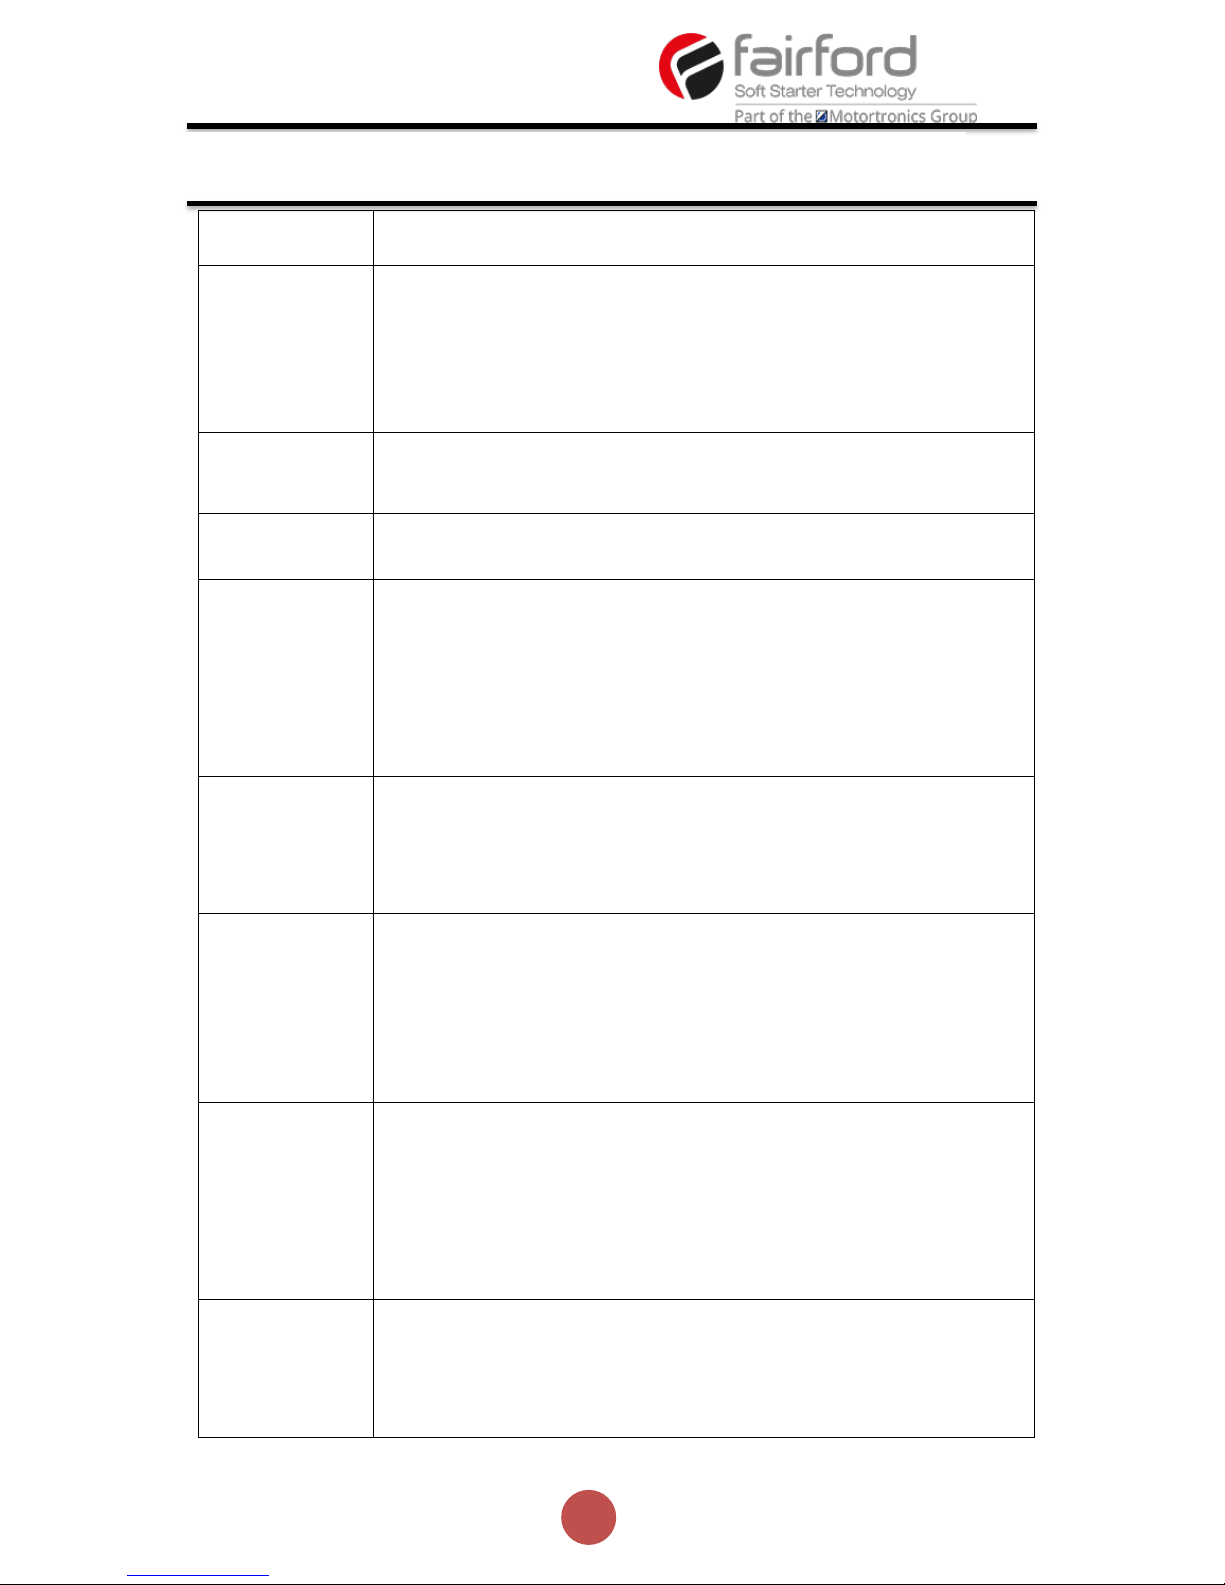
Level 0
Level 1
Level 2
Level 3
Advanced
Auto Reset
Reset Trips
Operation1
Operation2
Operation3
Operation4
Operation5
Operation6
Operation7
Operation8
Operation9
Operation10
I/O Input
Cntrl Mode
Cntrl Funct
Output
Relay 13 14
Relay 21 22
Log Save Log
Trip Log
Trip 0
Trip 1
Trip 2
Trip 3
Trip 4
Trip 5
Trip 6
Trip 7
Trip 8
Start Log
I Start
T Start
Stop Log
I Stop
T Stop
Totals Log
Total Events
Total Us On
Total Uc On
Total Starts
Total Runs
Total Stops
Total Trips
Total Us Off
Menu Structure (continued)
Page 33
32
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Device
Language
Factory Rst
Date
DateFormat
Time
USB To USB
From USB
Screen
Lock Enable
Passcode
Disp Time
Scroll
Firmware
Version
Update
Network
Address
Parity
Baud
CommsTime
Keypad
Keypad Pwr
Hardware
AGY100 Ver
AGY200 Ver
AGY300 Ver
AGY400 Ver
ODB Type
About
Serial No
MenuBuild
Model No
Version
Boot Ver
Trip Class
Motor Amps
Unit Amps
Rated Amps
Menu Structure (continued)
Page 34
33
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
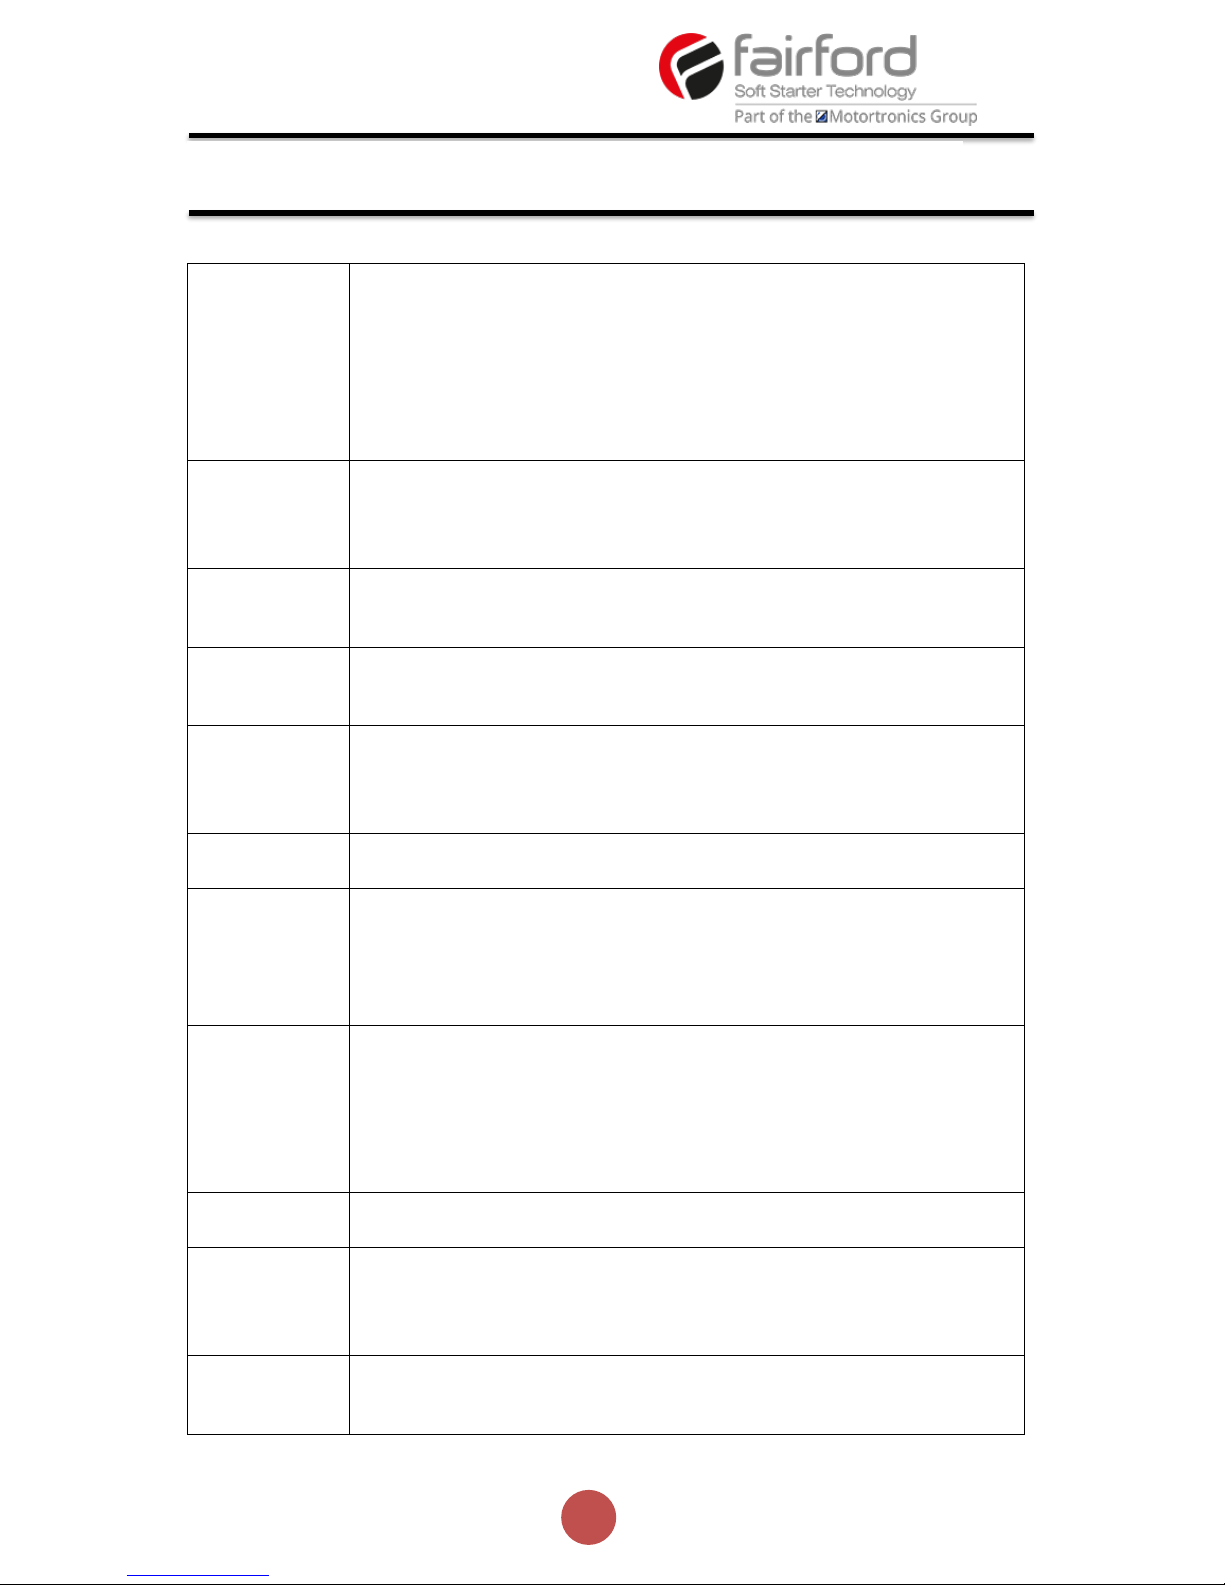
Address
Sets the Modbus address number
Application
The unit has numerous pre-set applications built in as standard.
Select the application best suited to the load.
The selected application will automatically change several parameters
and functions.
Depending on the application loaded the “Trip Class" may also change
Baud
Sets the serial communications baud rate
The available baud rates are 9600 19200 38400 57600 or 115200
Boot Ver
Software Version for the Bootloader
Cntrl Funct
Allows the Digital inputs to be mapped to different functions
Cntrl Mode must be set to "Remote"
Two Wire: D1 = Start (Reset) / Stop
Three Wire: D1 = Start (Reset) D2 = Stop
D2 Reset, D2 HoldStart , D2 Enable , D2 FireMode : Programs D2 as
shown
Cntrl Mode
Selects the method for starting and controlling the motor
Local: Control using the button on the keypad
Remote: Control using the terminals.
Modbus: Control via Modbus network
Comms
Detects if the communications bus has failed or become inactive.
To keep the bus active there must be at least one Modbus read or
write (any PNU) during the "Comms Time” period (ModbusPNU 147)
Trip On: Communication trip enabled.
Trip Off: External Trip is disabled
CommsTime
Communications trip Timeout period
To prevent a 'Communications Trip' (if enabled) the bus must be kept
active.
To keep the bus active there must be at least one Modbus read or write
(any PNU) during the
"Timeout ms” period
Cont Delay
Time allowed for external contactors to close.
Increase if contactors are driven by buffer relays or motor trips on phase
loss when start signal applied.
Decrease if response to start signal needs to be improved
Function Descriptions
Page 35
34
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
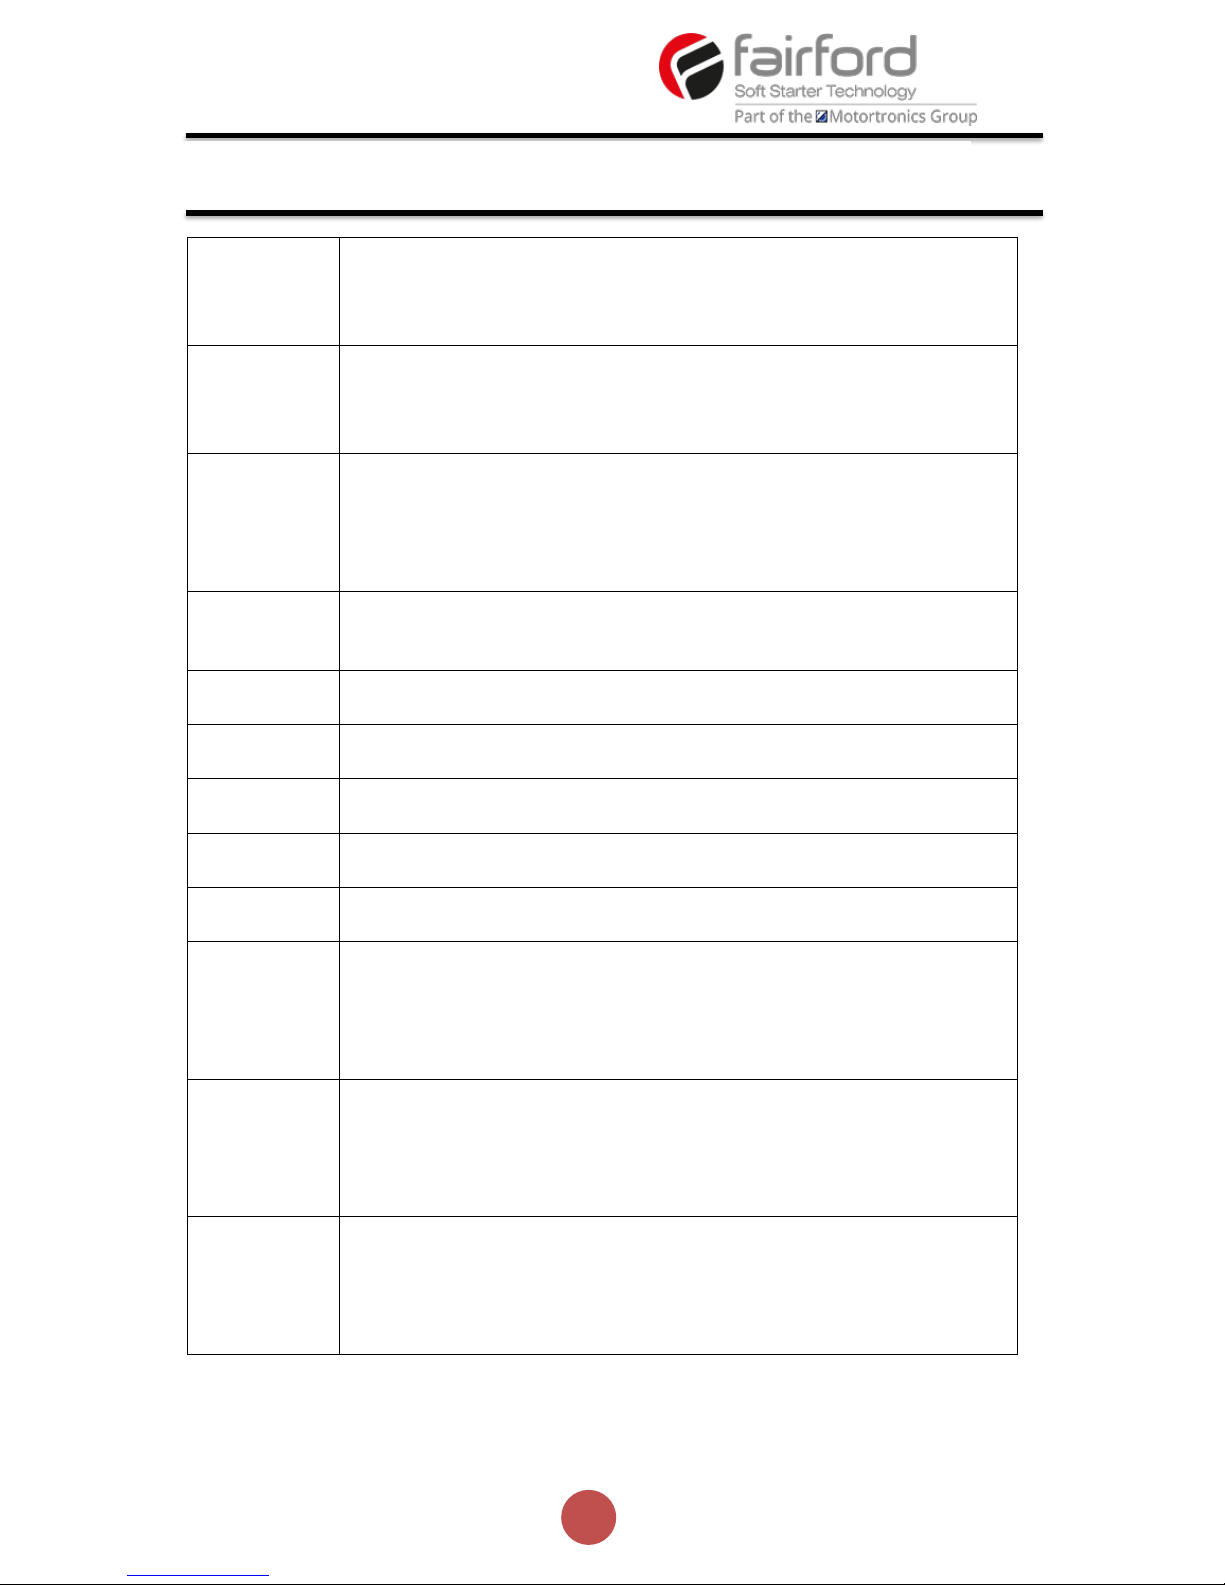
CT Fault
Detects if the internal current sensors have failed or reading a
very low level.
Trip On: The unit will trip if the internal current sensors fail or
the current measured falls to a very low level
Trip Off: Will continue to operate even if the sensor has failed.
Measurements and overload protection may be effected
Date
Enter current date
Date format can be set to either dd/mm/yyyy or mm/dd/yyyy. Refer to
"Date format" parameter.
DateFormat
Allows the date format to be changed
dd/mm/yy or mm/dd/yy or yy/mm/dd
Delay Angle
Internal firing delay angle in Degrees
Displayed for diagnostic purposes
Disp Time
Time for backlight on display
After the period set the back light on the screen will turn off
To reactivate touch screen anywhere. To disable set to 0
Factory Rst
Restores the unit to the factory defaults
Fan Fault
Detects if the cooling fans have failed.
Trip On: The unit trips if the cooling fans fitted to the unit fail.
Trip Off: Will continue to operate and is likely to trip on a thermal trip as
the heatsink will not be sufficiently cooled
Fire Mode
A special feature that allows the unit to operate with ALL of the trips OFF.
Set " Cntrl Funct" to "D2 FireMode" , Enabled when D2 is high
Although the unit will keep running in this mode it may become damaged.
In some instances, the damage may inhibit a subsequent starts
This is only to be used in an emergency
Frequency
The frequency of the 3-phase supply
From USB
Allows the user to load parameters stored on a USB flash drive
Uploads the parameters from the USB drive to the unit
Data is stored in CSV format.
HS Temp C
The temperature of the internal unit heatsink.
The unit will trip when the heatsink temperature exceeds 80°C.
Function Descriptions (continued)
Page 36
35
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
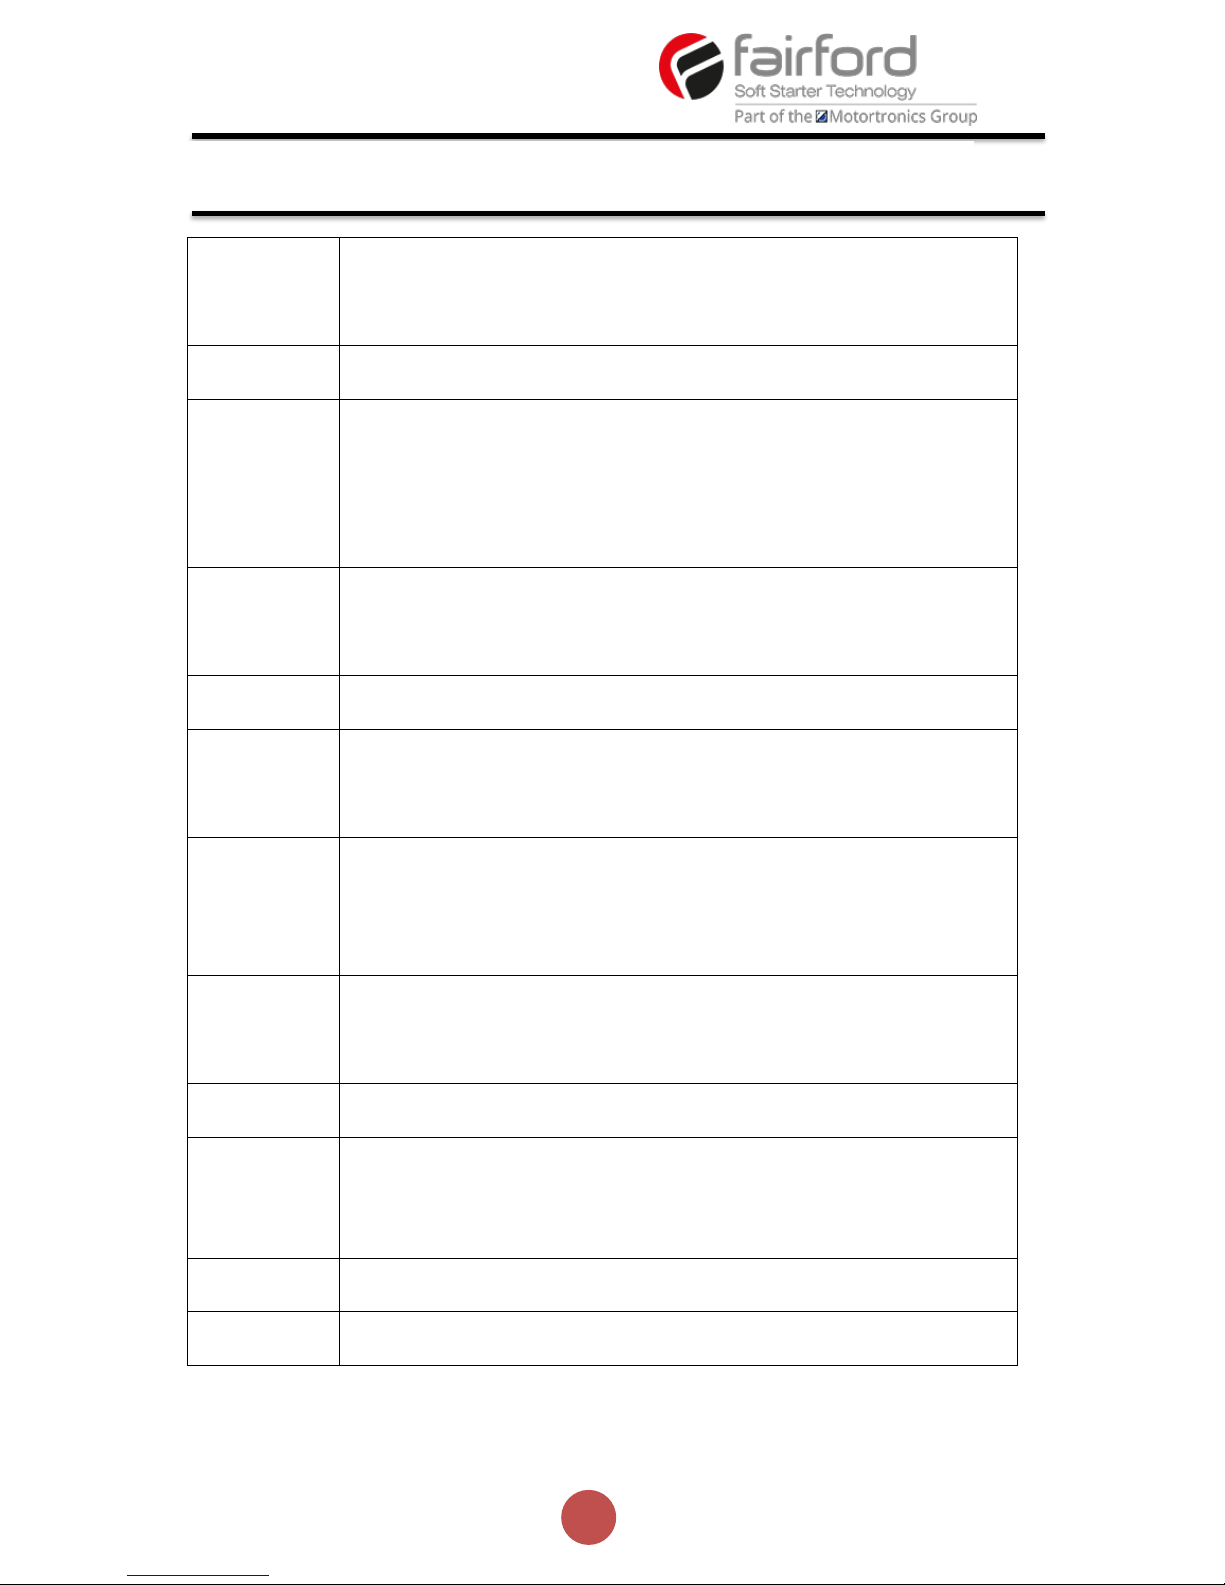
HS Temp F
The temperature of the internal unit heatsink.
The unit will trip when the heatsink temperature exceeds 176°F
The optional cooling fans will turn on if this temperature exceeds 104°F
I Limit
Selects trip or continue if the current limit has been active for too long
Trip On: The unit will trip
Trip Off: The start will continue regardless of the motor current level
I Low
This can be used to detect if the motor is running lightly loaded.
Trip On: The unit will trip. This feature is not active during soft start and
soft stop.
Trip Off: The unit will continue to operate regardless of motor current
I rms
The RMS motor current
Indicates average current of the 3 phases.
I Start
Displays the peak current during the last start.
I Stop
Displays the peak current during the last stop.
I1 rms
The RMS current on phase L1
I2 rms
The RMS current on phase L2
I3 rms
The RMS current on phase L3
Initial Volts
Percentage of the supply voltage applied to motor at the beginning of the
soft start.
Increase to provide more torque If the load fails to break away.
Decrease if the motor accelerates too quickly.
Kick Level
Percentage of the supply voltage applied to the motor during the ‘kick'
period
Increase to provide more torque If the load fails to break away.
Decrease if the motor accelerates too quickly.
Kick Start
Applies a short duration torque pulse to dislodge 'sticky' loads
On: The torque pulse is applied at start-up when complete the torque
drops to the "Initial Volts"
Off: The initial starting torque is defined by the "Initial Volts"
Function Descriptions (continued)
Page 37
36
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
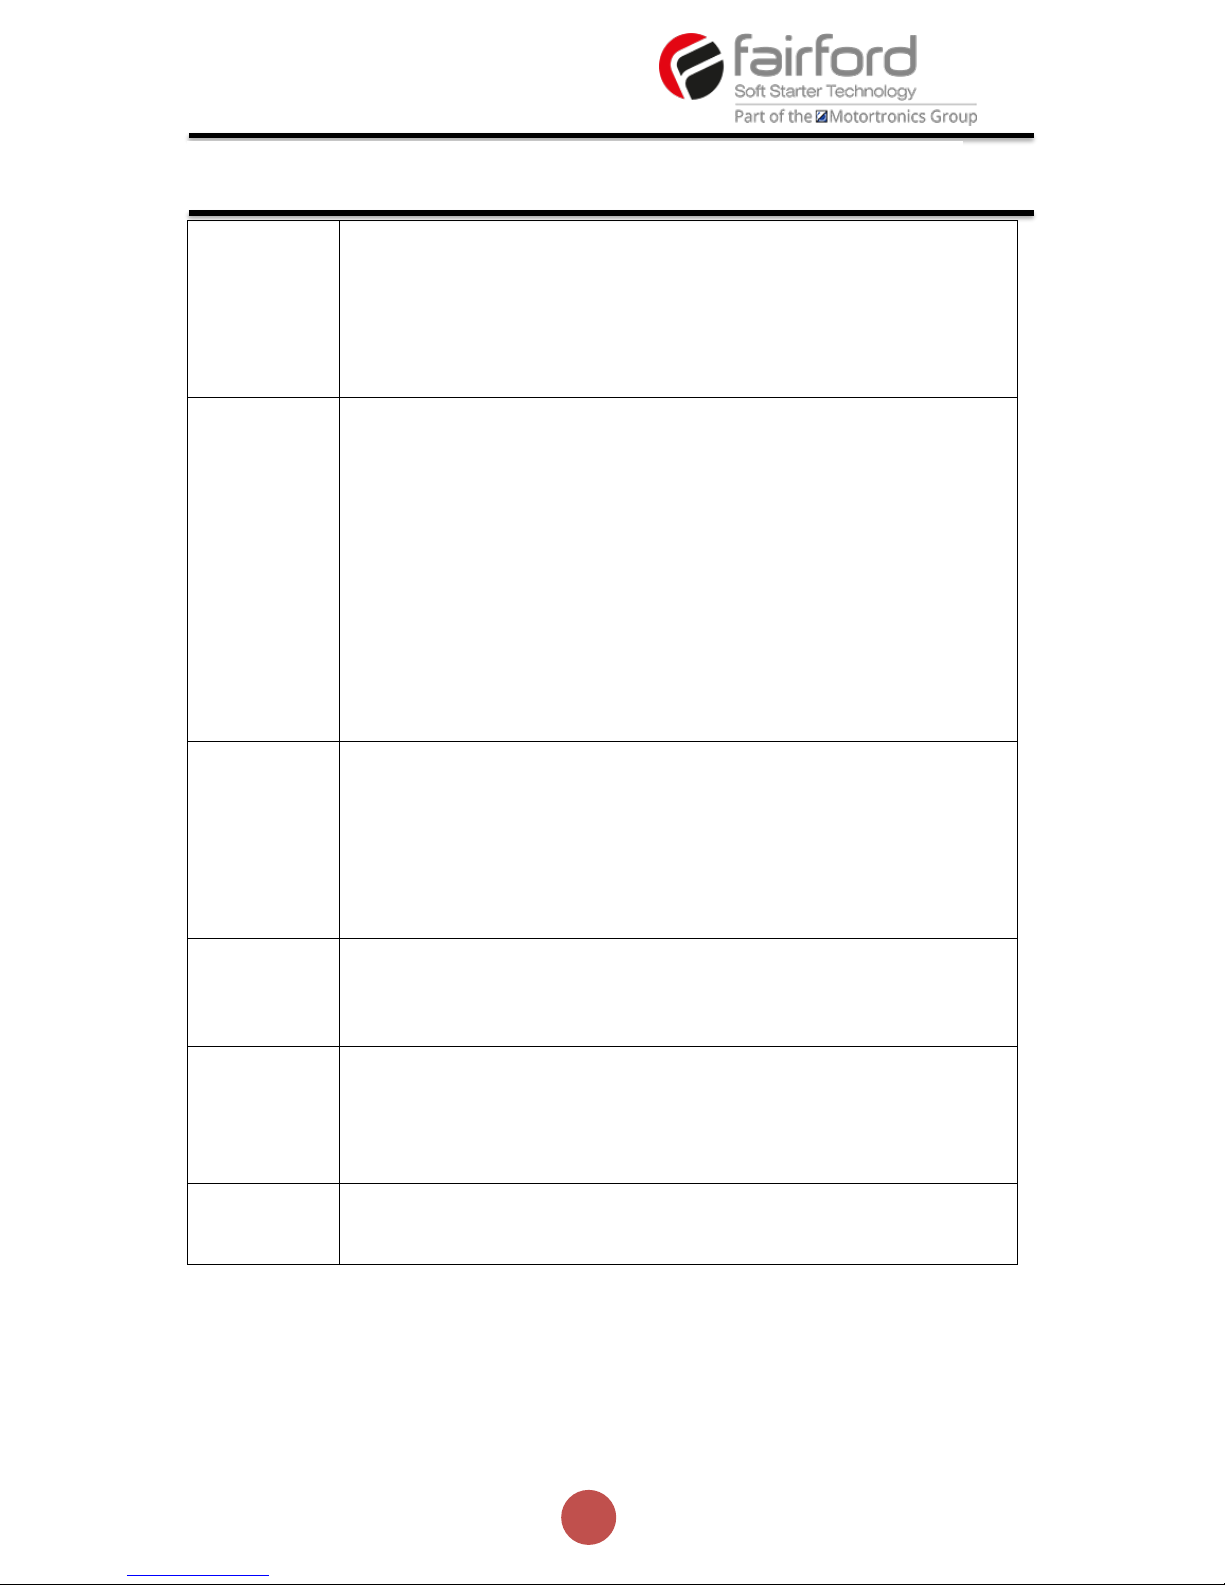
Kick Time
Time that the torque pulse is applied to load
Increase to provide more torque If the load fails to break away.
Decrease if the motor accelerates too quickly.
Last Trip
Limit Amps
The current in Amps at which the soft Start ramp is held.
Normally set to 350% of motor FLC.
Increase if motor fails to accelerate at required rate
The "Limit Amps" will affect actual time to start.
If set too low the motor may not accelerate to full speed.
Limit Time
The maximum time allowed for the current limit.
If the current limit is still active at the end of this period, the unit will
either 'Trip' or 'continue'
MenuBuild
Menu Version
Modbus
Enable
Enable using Modbus
On: The unit is enabled
Off: The unit is disabled
Modbus Reset
Reset using Modbus
On: The initial state required for a reset.
Off: The final state required for a reset.
To reset pulse high and then low
Modbus Start
Start / Stop using Modbus
On: Starts the unit
Off: Stops or Soft stops the unit
Model No
The device Model number stored at the point of manufacture
Motor Amps
This should be set to the Full Load Current shown on the motor plate
The overload works with multiples of the set "Motor Amps"
Also referred to as Motor FLA
MotorState
Indicates the unit operating State
Op Mode
Function Descriptions (continued)
Page 38
37
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Overheat
Detects if the internal temperature sensor has malfunctioned
Trip On: The unit will trip if the internal temperature sensor malfunctions
Trip Off: The unit will continue to operate even if the temperature sensor
has malfunctioned.
Operating with the Trip Off for prolonged periods may result in SCR failure
Overload
The unit has an "Overload" function that is an electronic
equivalent to a thermal overload.
Overload displays the overload capacity which is a measure of how close
the unit to tripping on "Overload Trip"
When "Irms" is greater than the "Overload Amps" the "Overload" increases
in accordance with the "Trip Class".
When "Current Irms" is less than "Overload Level" the "Overload"
decreases exponentially (if greater than 50%)
When the "Overload" reaches 100% the unit will trip.
During situations when "Motor Amps" is equal to "unit Amps" the overload
will indicate 50%
Overload Trip
The unit has an "Overload" function that is an electronic equivalent to a
thermal overload.
Trip On: The unit will trip when the "Overload" capacity (Modbus PNU 27)
exceeds 100%
Trip Off: The unit will continue to operate regardless of motor current
level
Ovld Amps
Determines the level in Amps at which the overload will start.
Normally set to 115% of the set "Motor Amps"
Reduce to speed up trip response
Parity
Sets the serial communications parity bit
The available parity options are None Even Odd
Also, sets the stop bits. No parity uses 2 stop bits. Odd or even parity uses
1 stop bit
Patch Addr 1
through 16
Used to arrange the Modbus Parameters into Groups
Refer to MAN-AGY-002-V01 for more details
Function Descriptions (continued)
Page 39
38
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Ph / SCR
Detects for various issues when "Starting" or " Stopping"
Detects for input phase loss / Output phase loss / SCR misfire
Trip On: Trips if there is an input phase loss / motor side phase loss / SCR
misfire
Trip Off: The unit will attempt to run although the operation may be
erratic.
Operating in this mode for prolonged periods may result in SCR failure
Phase Loss
Detects for various issues when the start signal is applied
Detects for input phase loss / input phase relationship
Trip On: Trips if there is an input phase loss / supply out of balance
Trip Off: The unit will attempt to run although the operation may be
erratic.
Operating in this mode for prolonged periods may result in SCR failure
Rated Amps
Unit Class20 / Class30 Current Rating
RelayFunct
Allows the n/c relay (21 -22) to be reconfigured
Available options are 22 = TOR or 22 = ERR
Remote
For safety reasons the unit will trip during some operations if the remote
start signal is active
Trip On: Trips if the remote start signal is active when the unit is powered
up or a reset is applied.
Trip Off: The unit will not trip and may start unexpectedly if the start signal
is accidently left active.
Rotation
Indicates the phase sequence of the incoming supply.
RYB = ABC = L1-L2-L3
RBY = ACB = L1-L3-L2
Save Log
Download the full log file on to the USB stick
The unit logs several parameters during normal and fault conditions
Data is stored in CSV format. Please send all downloaded files to Fairford
on request
Serial No
The device serial number stored at the point of manufacture
Shear Amps
The current in Amps that will cause a "Shear Trip"
A trip will occur if the motor current is greater than the "Shear Amps” for
the "Shear Time"
Function Descriptions (continued)
Page 40

39
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Shear TIme
The trip time for the Shearpin trip
A trip will occur if the motor current is greater than the "Shear Amps" for
the "Shear Time"
Shearpin
The Shearpin is an electronic equivalent of a mechanical Shearpin
Trip On: The unit will trip. This feature is not active during soft start and
soft stop.
Trip Off: The unit will continue to operate regardless of motor current
level
Start Time
Time taken to soft start from the "Initial Volts" to the end of the start
Normally set between 5 and 30 seconds.
Actual time to get to full voltage depends on the "Limit Amps".
If set too long the motor can be at speed before the end of the time set.
Stop Time
The time taken to soft stop from full voltage to the end of the stop
Normally set between 15 and 30 seconds.
Actual time to get to the final voltage depends on the "Limit Amps".
If set too long the motor may reach zero speed before the end of the time
set.
Store Param
Saves all Read /Write parameters to non-volatile memory
Yes: Parameters are permanently written
No: Parameters remain changed until next power cycle
System
Detects if the Control Board has failed to operate normally
Trip On: System Trip enabled.
Trip Off: System Trip disabled.
T Start
Displays the time of the last start
T Stop
Displays the time of the last stop
Tempunit
Selects °C or °F for displayed temperatures
°C: All displayed temperatures are °C
°F: All displayed temperatures are °F
Time
Allows the time to be changed to 'local' time
By default, the time is set to GMT
Function Descriptions (continued)
Page 41
40
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
To USB
Allows the user to save parameters
Downloads the parameters from the unit to the USB drive
Data is stored in CSV format.
Total Events
The total number of events that have been recorded in the log file
Total Run
The total number of times the unit as successfully got to the "Running"
State
The Running state is active when the unit is operating at full voltage.
When operating at full voltage the internal bypass relays are closed.
Total Starts
The total number of successful starts
Total Uc On
The total number of times the unit has been powered up.
Te unit is powered up by applying a voltage to Uc
Uc will be 24V or 110V / 230V depending on model
Total Uc Off
The total number of times the unit has been powered down.
Te unit is powered down by removing the voltage at Uc
Uc will be 24V or 110V / 230V depending on model
Function Descriptions (continued)
Page 42
41
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Trip 0
Displays the last Fault trip
Trip 1
Displays the last Fault trip -1
Trip 2
Displays the last Fault trip -2
Trip 3
Displays the last Fault trip -3
Trip 4
Displays the last Fault trip -4
Trip 5
Displays the last Fault trip -5
Trip 6
Displays the last Fault trip -6
Trip 7
Displays the last Fault trip -7
Trip 8
Displays the last Fault trip -8
Unit Amps
unit Class10 Current Rating
Version
Software Version for the Main control PCB
Software version recorded in log file
Window 1
though 24
Used to arrange the Modbus Parameters into Groups
Window Code
Used to arrange the Modbus Parameters into Groups
Window View
Used to arrange the Modbus Parameters into Groups
Function Descriptions (continued)
Page 43
42
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
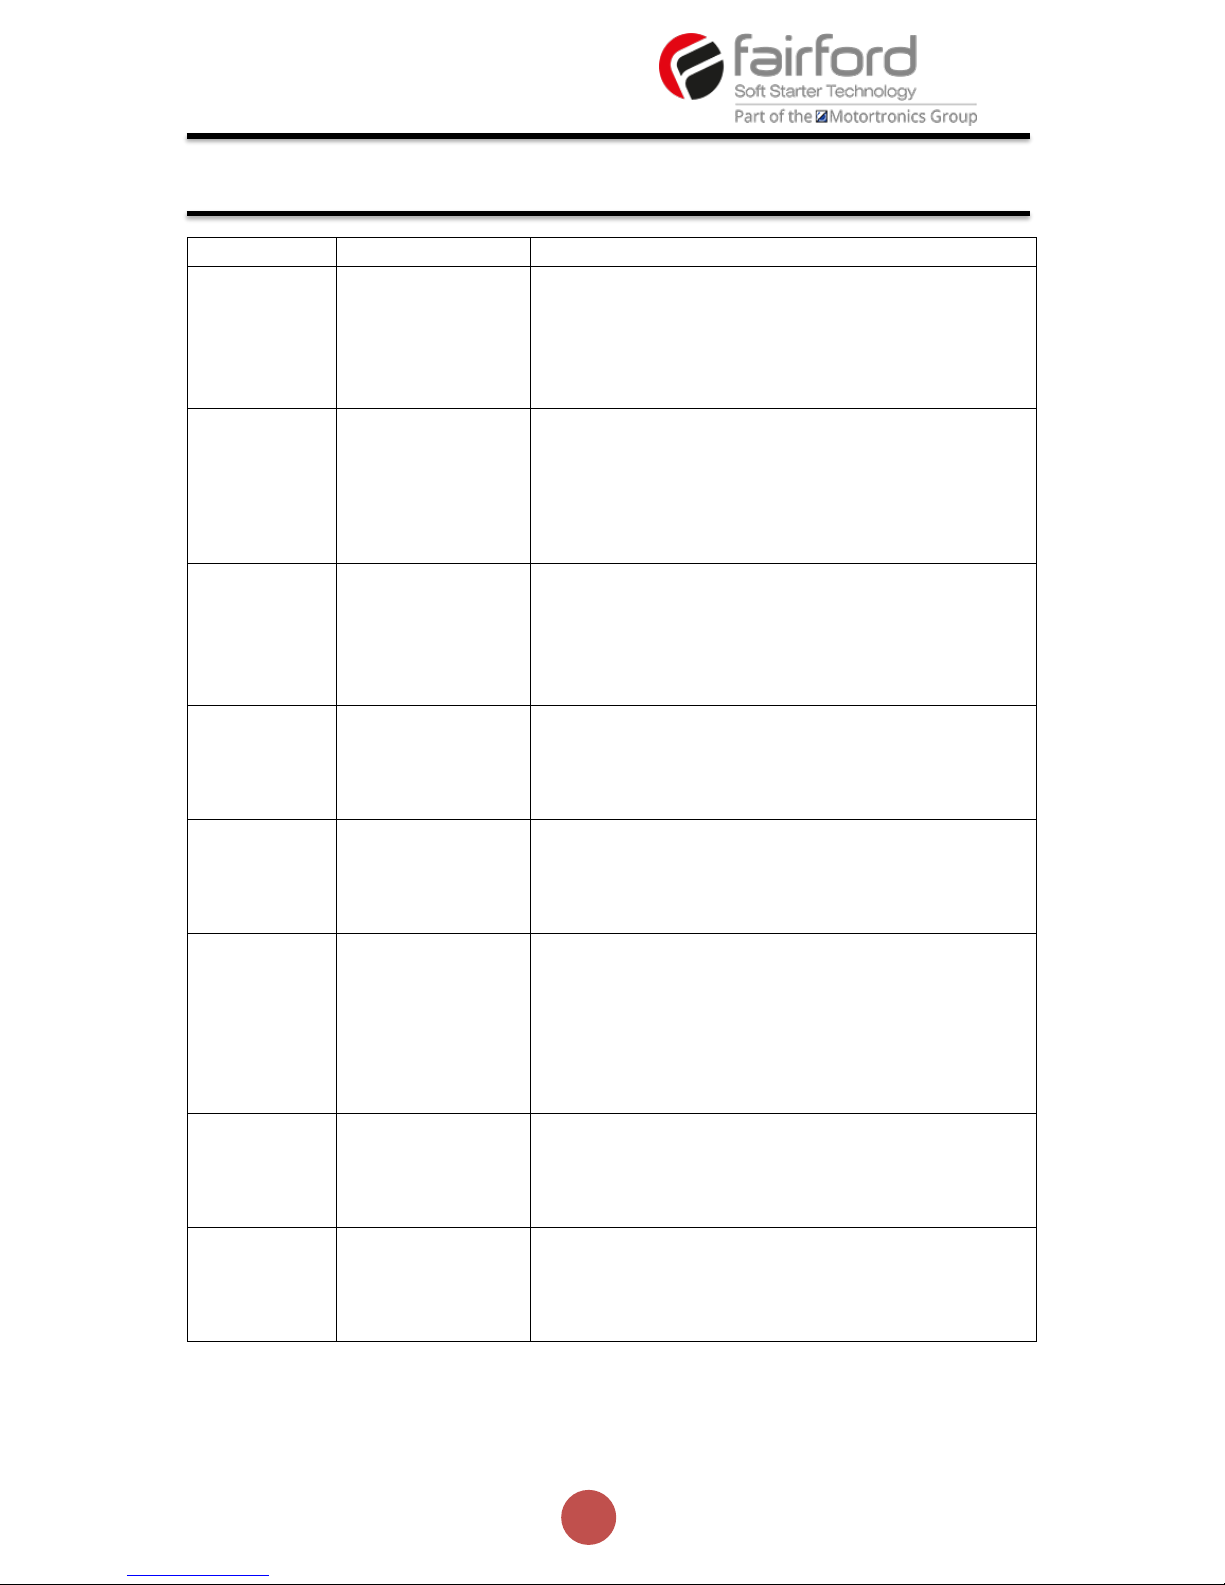
Trip Code
Trip Name
Description
101-199
Ph Loss
Input phase voltage missing or motor discontinuity at the
instant of startup.
Check all incoming and outgoing connections.
If a main contactor is being controlled by a digital output
check contactor delay is sufficient
201-299
Thermal
Internal heatsink temperature has exceeded 90°C
It is possible the Unit is operating outside specified limits.
Check enclosure ventilation and airflow around the Unit. If
the unit trips immediately the internal temperature sensor
could be faulty.
301-399
Ph / SCR
Input phase voltage missing or motor discontinuity or SCR
failure
Check all incoming and outgoing connections.
ISOLATE SUPPLY.
Check by measuring the resistance between L1-T1 L3-T3 (
Anything < 10R is assumed short circuit)
601-699
Uc Low
The internal control supply of the Unit level has fallen to a
low level
Can be caused by a weak 24VDC control supply.
Ensure 24VDC supply meets the requirements specified in
the Quick Start Guide.
1101-1199
Low Amp
The motor current has been lower than the low trip level for
the low trip time
This trip is not active during soft start and soft stop and is
"off" by default.
If the low current trip is not required turn "off" in "Trip
Settings".
1201-1299
Limit
The motor has been held in current limit longer than the
"Current limit Time"
It is likely that the current limit level has been set too low for
the application.
Increase the current limit level or timeout period.
1301-1399
Overload
The "Overload" has exceeded 100%
The Unit is attempting to start an application that is outside
its capacity or it is starting too often.
Refer to the overload trip curves to determine whether the
Unit has been sized correctly.
1401-1499
Shear
The motor current has been higher than the "Shearpin Trip
Level" for the trip time.
This trip is not active during soft start and soft stop and is
"off" by default.
If Shearpin trip is not required turn "off" in "Trip Settings".
Trip and Fault Codes
Page 44
43
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
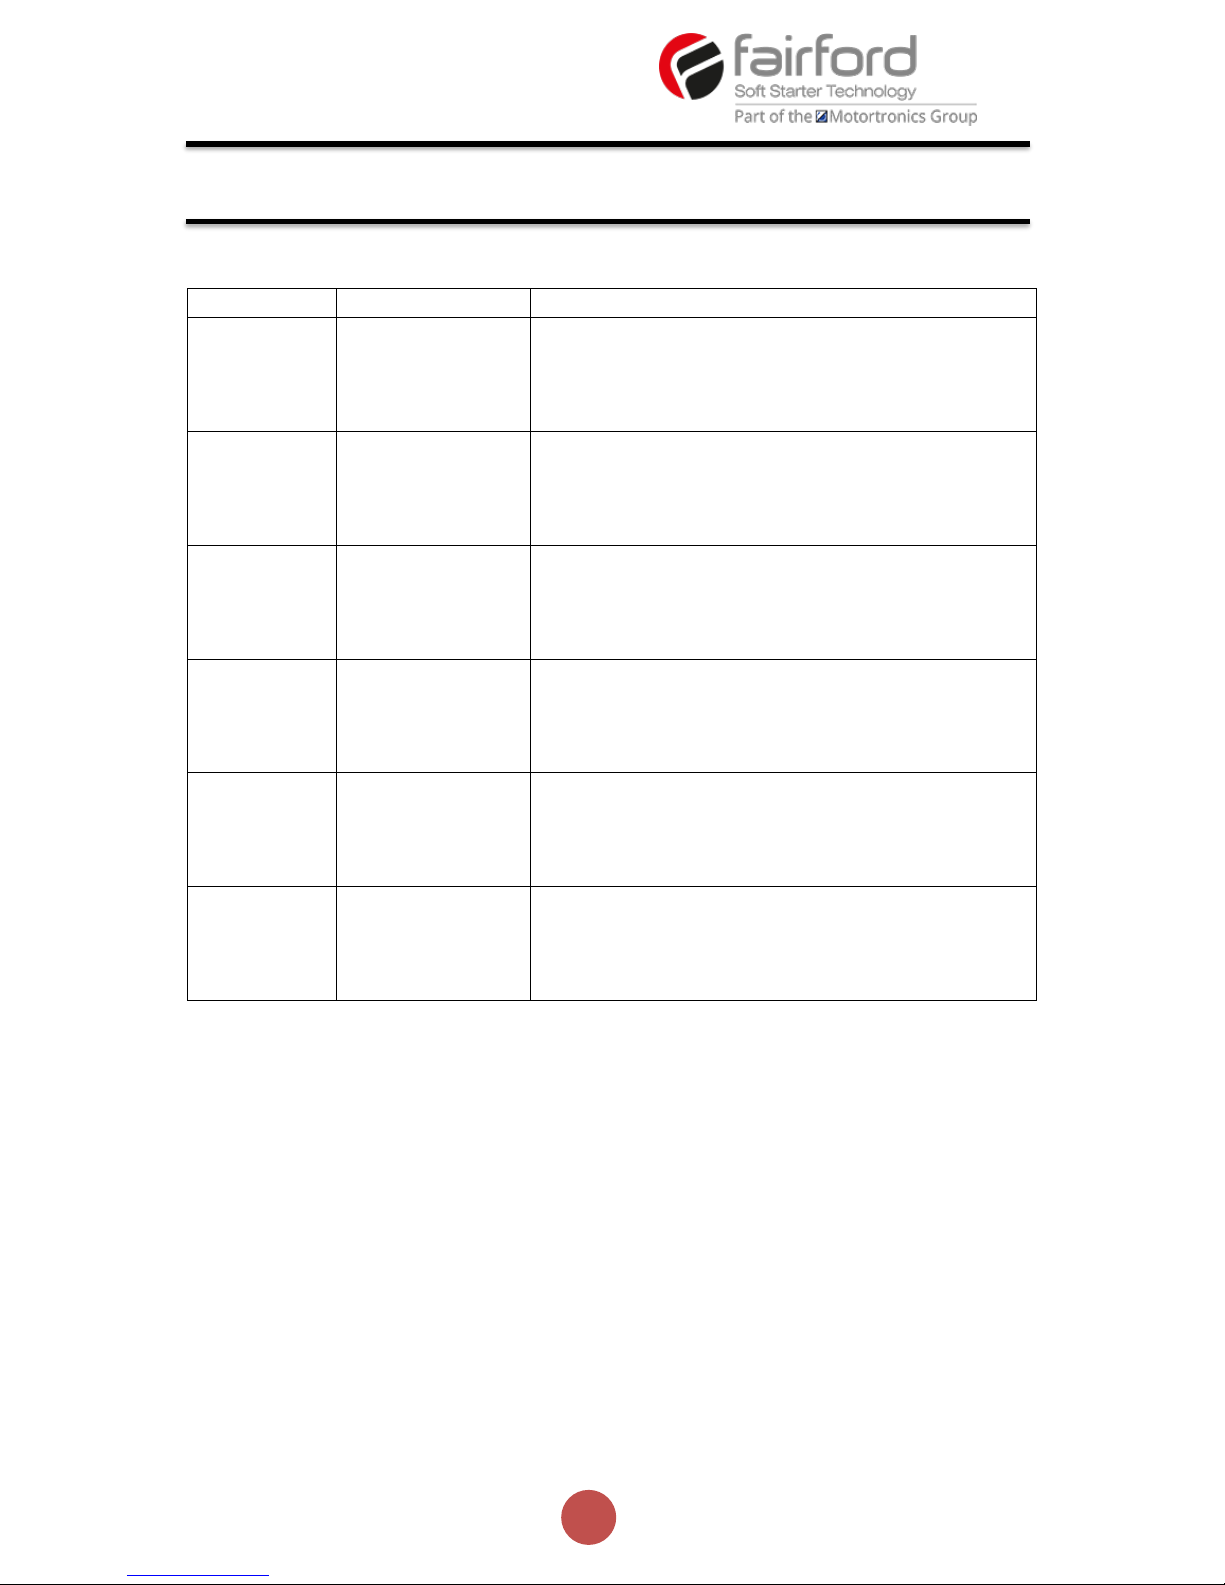
Trip Code
Trip Name
Description
1701-1799
Comms
Communications failure
The command or status PNU has not been polled in
the time set in the "Timeout" period
If the communication trip is disabled the Unit cannot
be stopped in the communications fail
1801-1899
Bypass
One or more of the internal bypass relays has failed to
close or open
The internal bypass relay has failed or the control
supply is to weak.
Ensure 24VDC supply meets the requirements
specified in the Quick Start Guide.
2001-2099
Remote
The remote start signal is active.
The remote start signal was active during power up or
Reset or Parameter Load.
Turn off remote or if Remote On trip is not required
turn "off" in "Trip Settings"
2101-2199
Rotation
Checks the input phase rotation
The phase rotation is opposite to that required.
Change phase rotation or if the trip is not required turn
"off" in trip settings.
2201-2299
Op1
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
2301-2399
CT Fault
Current sensor failure
One or more of the internal sensors used to measure
current has failed or is reading a low value.
Check the connections to the supply and motor as
disconnection will result in a zero current reading.
Check the plate FLA of the motor being controlled is at
least 25% of the "i-motor" rating
11001-11099
Op2 Pnu
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
12001-12099
Op2 Mod
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
Trip and Fault Codes (continued)
Page 45
44
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
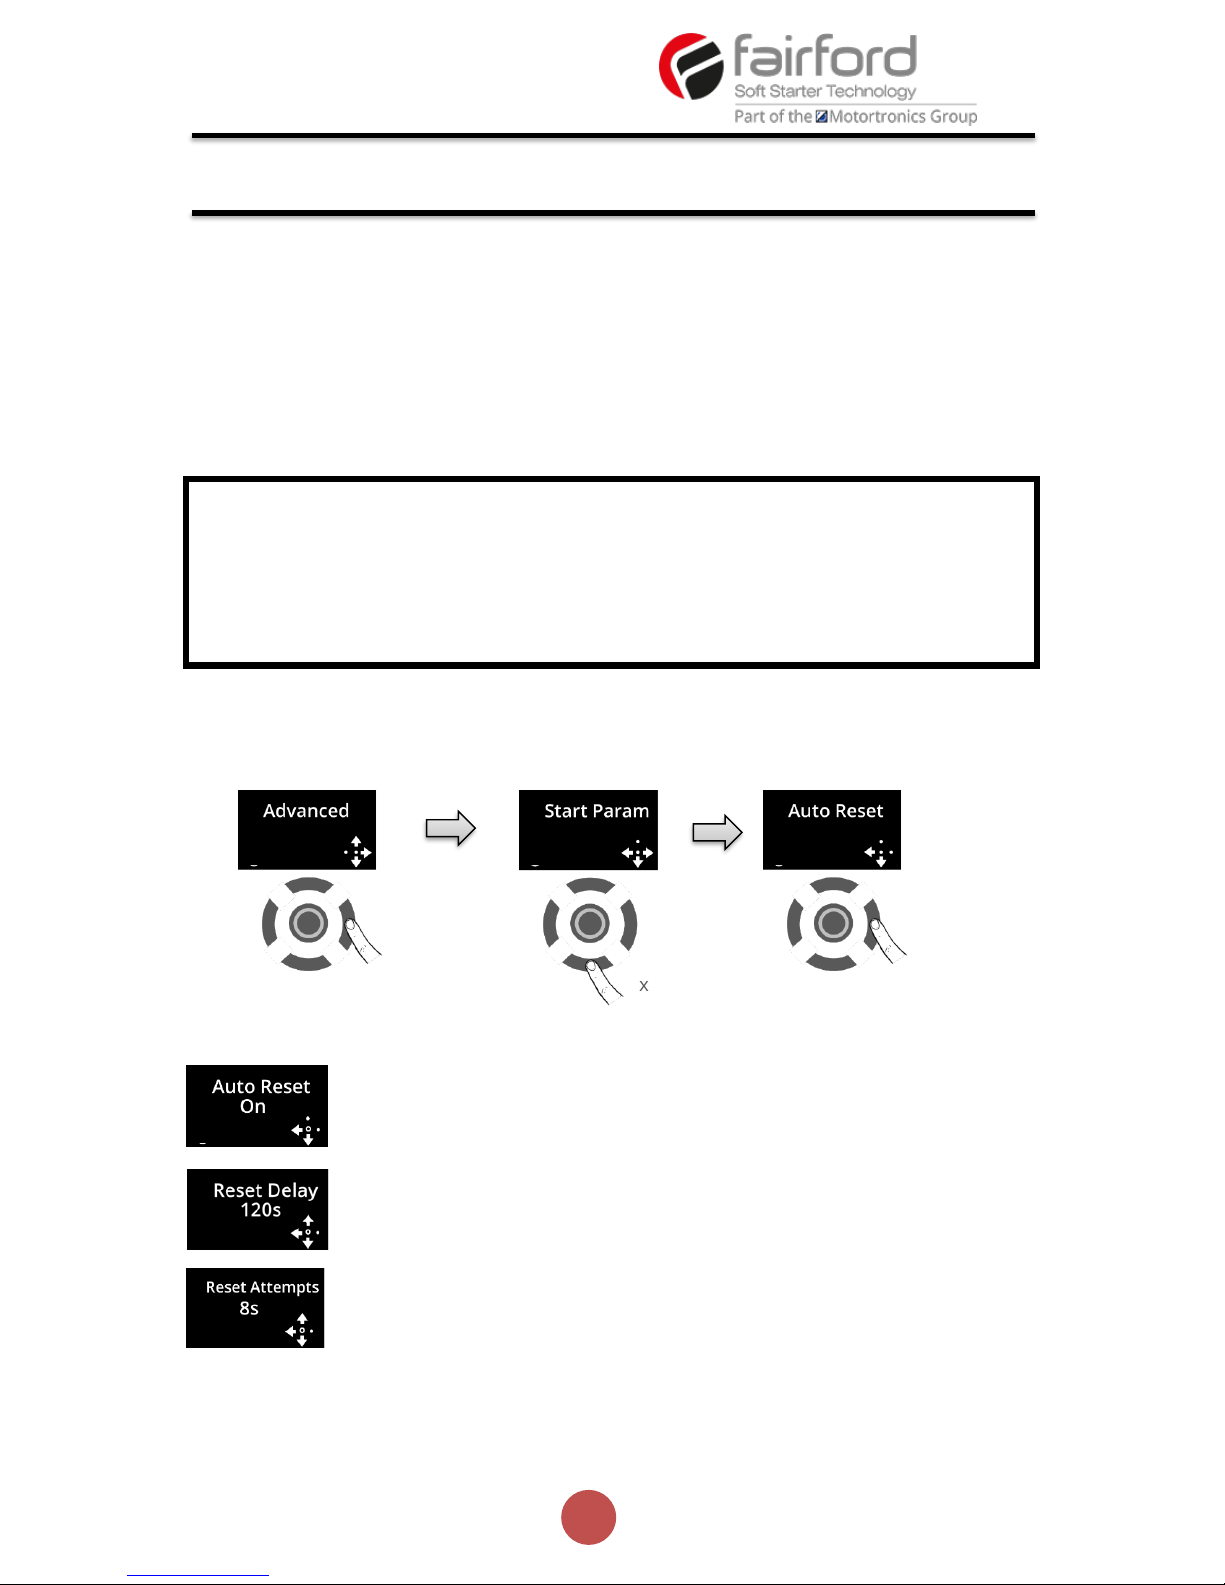
Trip Code
Trip Name
Description
13001-13099
Op2 Mon
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
14001-14099
Op2 Men
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
15001-15099
Op2 Keys
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
16001-16099
Op2 Motr
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
17001-17099
Op2 Log
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
18001-18099
Op2 Disk
Fail Safe operation
A process associated with the Control Board has been
affected and is unable to recover automatically
Trip and Fault Codes (continued)
Page 46
45
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
The Auto Reset feature automatically resets a selected number of faults and then attempts a
start without user intervention. The time between the resets and the number of reset attempts
are both programmable. If the Auto Reset has been successful, the Starter must operate trip free
for a set time before the counters are re-initialised. If the number of attempts exceeds the set
value, the Auto Reset terminates, and the counters will be re-initialised when a Reset or Stop
signal is given by the user.
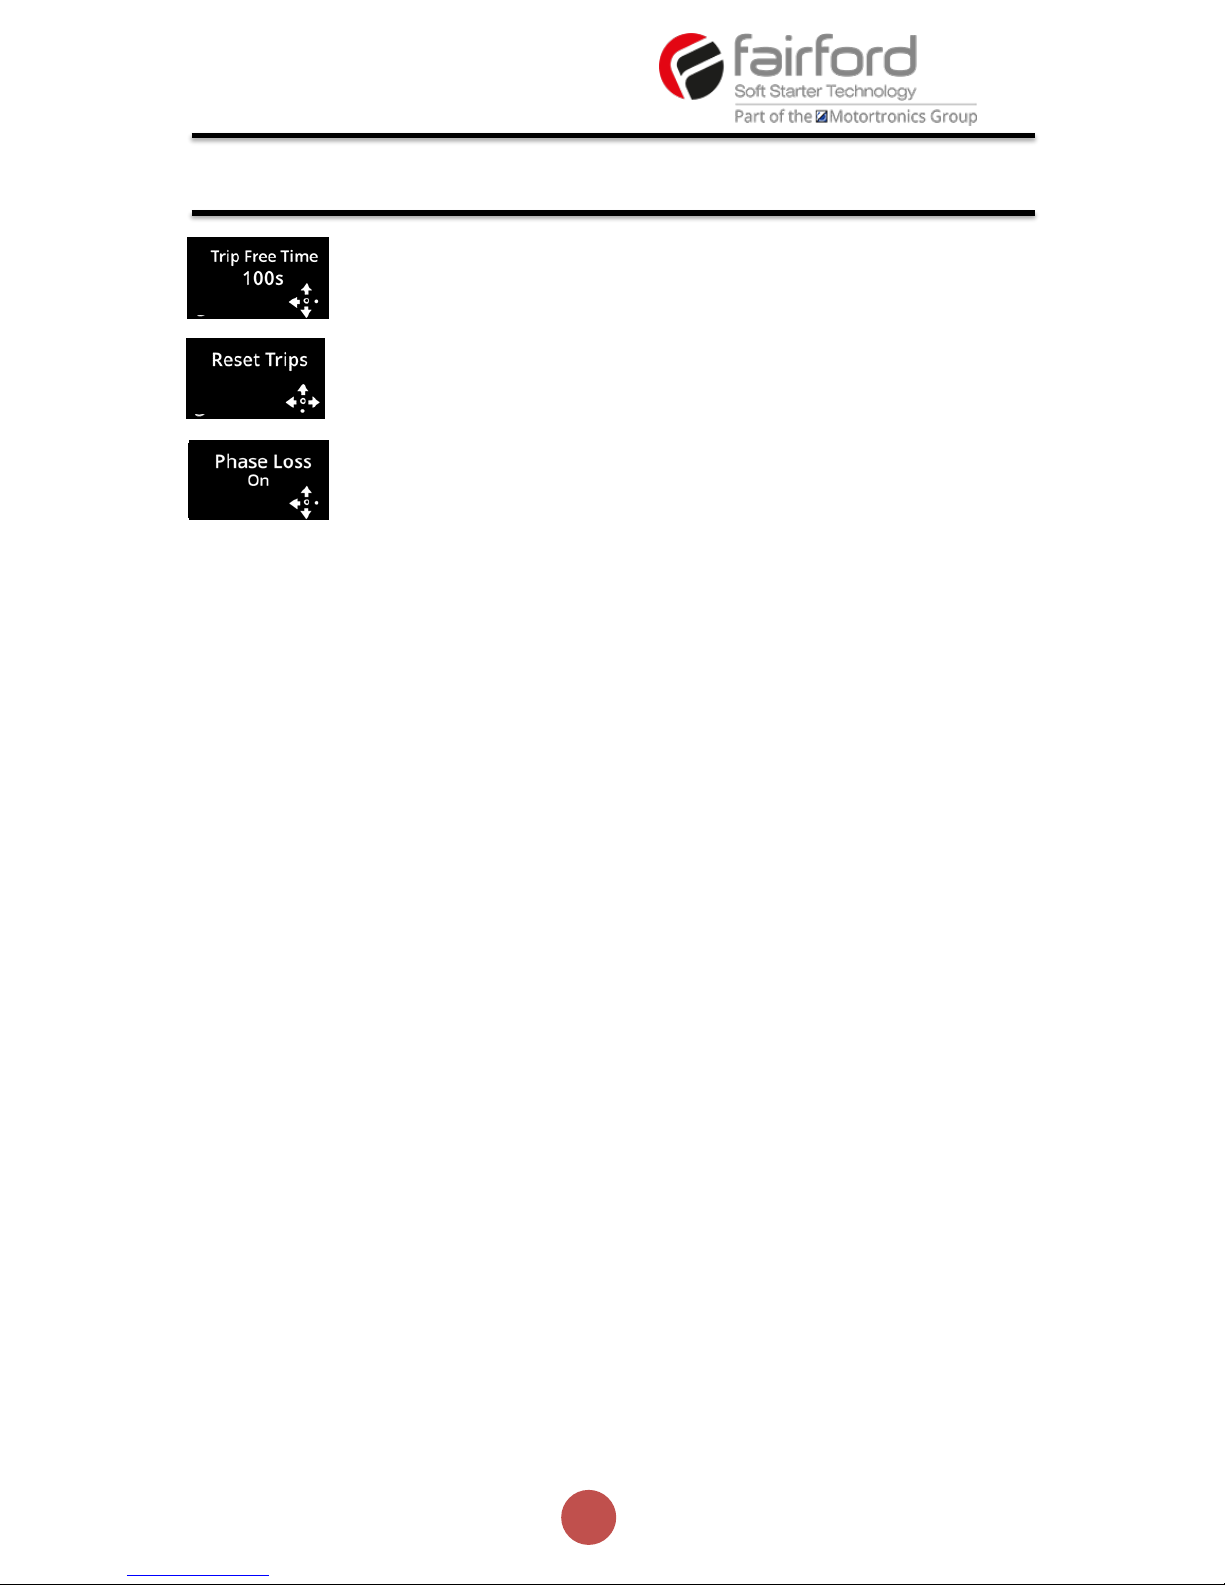
The Auto-Reset function is accessible from the Advanced Menu (see Auto-Reset section of
parameter summaries) :
From the Auto Reset menu various functions are accessed:
Auto Reset Function
WARNING:
When Auto Reset is enabled, a tripped motor may restart automatically after the Reset Delay
time. This may result in equipment damage or personal injury if the function is used in an
unsuitable application. Do not use this function without considering applicable local,
national, and international standards, regulations, or industry guidelines
x 5
Toggles the Auto Reset On or Off
Sets delay between trip and Auto Reset
Number of permissible Auto Reset attempts
Page 47
46
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset Assignable Trips
Phase Loss
Thermal
ScrFire
Ph / SCR
HzHighLow
UcLow
SCRSen
Fan
Spare900
Spare1000
I Low
I Limit
Overload
Shearpin
Spare1500
External
Comms
Bypass
Control
Remote
Rotation
Operation 1
CT Fault
Operation2
Operation3
Operation4
Operation5
Operation6
Operation7
Operation8
Operation9
Operation10
Auto Reset Function (continued)
Press Right key to assign trips to Auto Reset function
Example of trip assigned to Auto Reset function (Up/Down keys to view and
select trips
The time the unit must be trip free before the counter is set to zero
Page 48
47
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset Function Descriptions
AR Attempts
The number of Reset Attempts remaining.
AR Delay
The amount of time remaining in the Reset Delay counter
AR Exceeded
Indicates that the maximum number of reset attempts has been reached.
Yes : The number of reset attempts has exceeded the value set
No : The number of reset attempts has not exceeded the value set
To map to digital output refer to PNU154/PNU300
AR Pending
Indicates that the Reset Delay counter is counting down
Yes : The Auto Reset Delay is counting down
No : The Auto Reset Delay is not counting down
To map to digital output refer to PNU154/PNU300
AR Trip Event
The trip that occurred just prior to the auto reset
AR Trip Free
The amount of time remaining in the Trip Free Time counter
Auto Reset Function (continued)
Page 49
48
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset
Enables the Auto Reset Feature
Refer to Auto Reset section for more details
On : The Auto Reset feature is enabled
Off : The Auto Reset feature is disabled and all counters will be reinitialised
Bypass
Allows the user to select whether the unit will auto reset if a Bypass Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Comms
Allows the user to select whether the unit will auto reset if a Comms Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Control
Allows the user to select whether the unit will auto reset if a Control Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
CT Fault
Allows the user to select whether the unit will auto reset if a CT Fault Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
External
Allows the user to select whether the unit will auto reset if a External Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Auto Reset Function (continued)
Page 50
49
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Fan
Allows the user to select whether the unit will auto reset if a Fan Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
HzHighLow
Allows the user to select whether the unit will auto reset if a HzHighLow
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
I Limit
Allows the user to select whether the unit will auto reset if a I Limit Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Operation 1
Allows the user to select whether the unit will auto reset if a Operation1
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Operation10
Allows the user to select whether the unit will auto reset if a Operation10
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Operation2
Allows the user to select whether the unit will auto reset if a Operation2
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Auto Reset Function (continued)
Page 51
50
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Operation3
Allows the user to select whether the unit will auto reset if a Operation3
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Operation4
Allows the user to select whether the unit will auto reset if a Operation4
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Operation5
Allows the user to select whether the unit will auto reset if a Operation5
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Operation6
Allows the user to select whether the unit will auto reset if a Operation6
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Operation7
Allows the user to select whether the unit will auto reset if a Operation7
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Operation8
Allows the user to select whether the unit will auto reset if a Operation8
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Auto Reset Function (continued)
Page 52
51
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Operation9
Allows the user to select whether the unit will auto reset if a Operation9
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Overload
Allows the user to select whether the unit will auto reset if a Overload Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Ph / SCR
Allows the user to select whether the unit will auto reset if a Ph / SCR Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Phase Loss
Allows the user to select whether the unit will auto reset if a Phase Loss
Trip occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Relay 13 14
Allows the n/c relay (13 -14) to be reconfigured
Available options are End Of Start or Fault or Run or Pending or Exceeded
Remote
Allows the user to select whether the unit will auto reset if a Remote Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Auto Reset Function (continued)
Page 53
52
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Reset
Attempts
The number of restart attempts allowed before the Auto Reset terminates.
If the Auto Reset has been successful, the counter is reset back to its
maximum value when the unit has been running fault free for the Trip
Free Time.
If the Auto Restart has been unsuccessful the counters are re-initialised by
applying a reset signal or removing the start signal. If this PNU is set to
zero at any point the Auto Reset feature will terminate and the counters
will be re-initialised
The number of attempts remaining can be viewed in the Monitor menu
Reset Delay
The delay between the trip event and the automatic reset, the unit will restart following the reset if the start signal is active
If this is set to zero at any point the Auto Reset feature will terminate and
the counters will be re-initialised
When the delay is active the Restart Pending parameter is set and the time
remaining can be viewed in the monitor menu.
Rotation
Allows the user to select whether the unit will auto reset if a Rotation Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
ScrFire
Allows the user to select whether the unit will auto reset if a ScrFire Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
SCRSen
Allows the user to select whether the unit will auto reset if a SCRSen Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Auto Reset Function (continued)
Page 54
53
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Shearpin
Allows the user to select whether the unit will auto reset if a Shearpin Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Thermal
Allows the user to select whether the unit will auto reset if a Thermal Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Trip Free Time
The time the unit must be run trip free before the counters are reinitialised back to zero.
If this PNU is set to zero at any point the Auto Reset feature will terminate
and the counters will be re-initialised
The Trip Free Time can be viewed in the Monitor menu
UcLow
Allows the user to select whether the unit will auto reset if a UcLow Trip
occurs
On : The trip will auto reset when the Reset Delay reaches zero.
Off : The trip will not auto reset
Auto Reset Function (continued)
Page 55
54
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Two-Wire, Three-Wire and Communications control (Control Supply maintained)
The Auto reset operates with two-wire, three-Wire and communications start / stop.
In Two-Wire the motor will not start if the start signal is low, however in 3-wire and communications control
the motor may start without a direct start signal. (Although it is implied as no stop had been given during the
reset delay period)
Control supply Loss
When the control supply is removed the microcontroller is unable to make calculations in real time. To
overcome this the calculations are made retrospectively when the starter powers up
Two Wire: Following a control supply loss the Start signal must be retained. (Fig 2)
Three Wire: The state of the start signal is saved when the control supply is removed and if it was set to ‘start’
the Auto Reset will continue at power up. When operating in this mode the motor may start at power up
without a start signal being present (Fig3)
Modbus / Communications: The state of the start signal is saved when the control supply is removed and if it
was set to ‘start’ the Auto Reset will continue at power up. When operating in this mode the motor may start
at power up without a start signal being present (Fig3)
Auto Restart Termination: If the time to re-establish the power exceeds the Reset Delay x Reset Attempts the
Auto Reset Terminates
Overload Trip
Following an overload trip (1301) the overload % will be at 100% and then cool exponentially to 0% after
several minutes. If a re-start is attempted too soon the starter will trip again as the overload % would not have
cooled to a sufficient level. (Fig 5)
It must be ensured the Reset Delay is long enough to allow the overload to cool. This is also the case for the
heatsink over temperature trip.
Remote Start on Trip
If Auto Reset is turned on some of the Remote Start On trips are disabled and will be ignored.
Hand Auto (Synergy Only)
If the Hand Auto option is selected the Hand selection will override the Auto Reset.
The Auto Reset will be terminated, and the counters will be re-initialised.
Auto Reset Function (continued)
Page 56
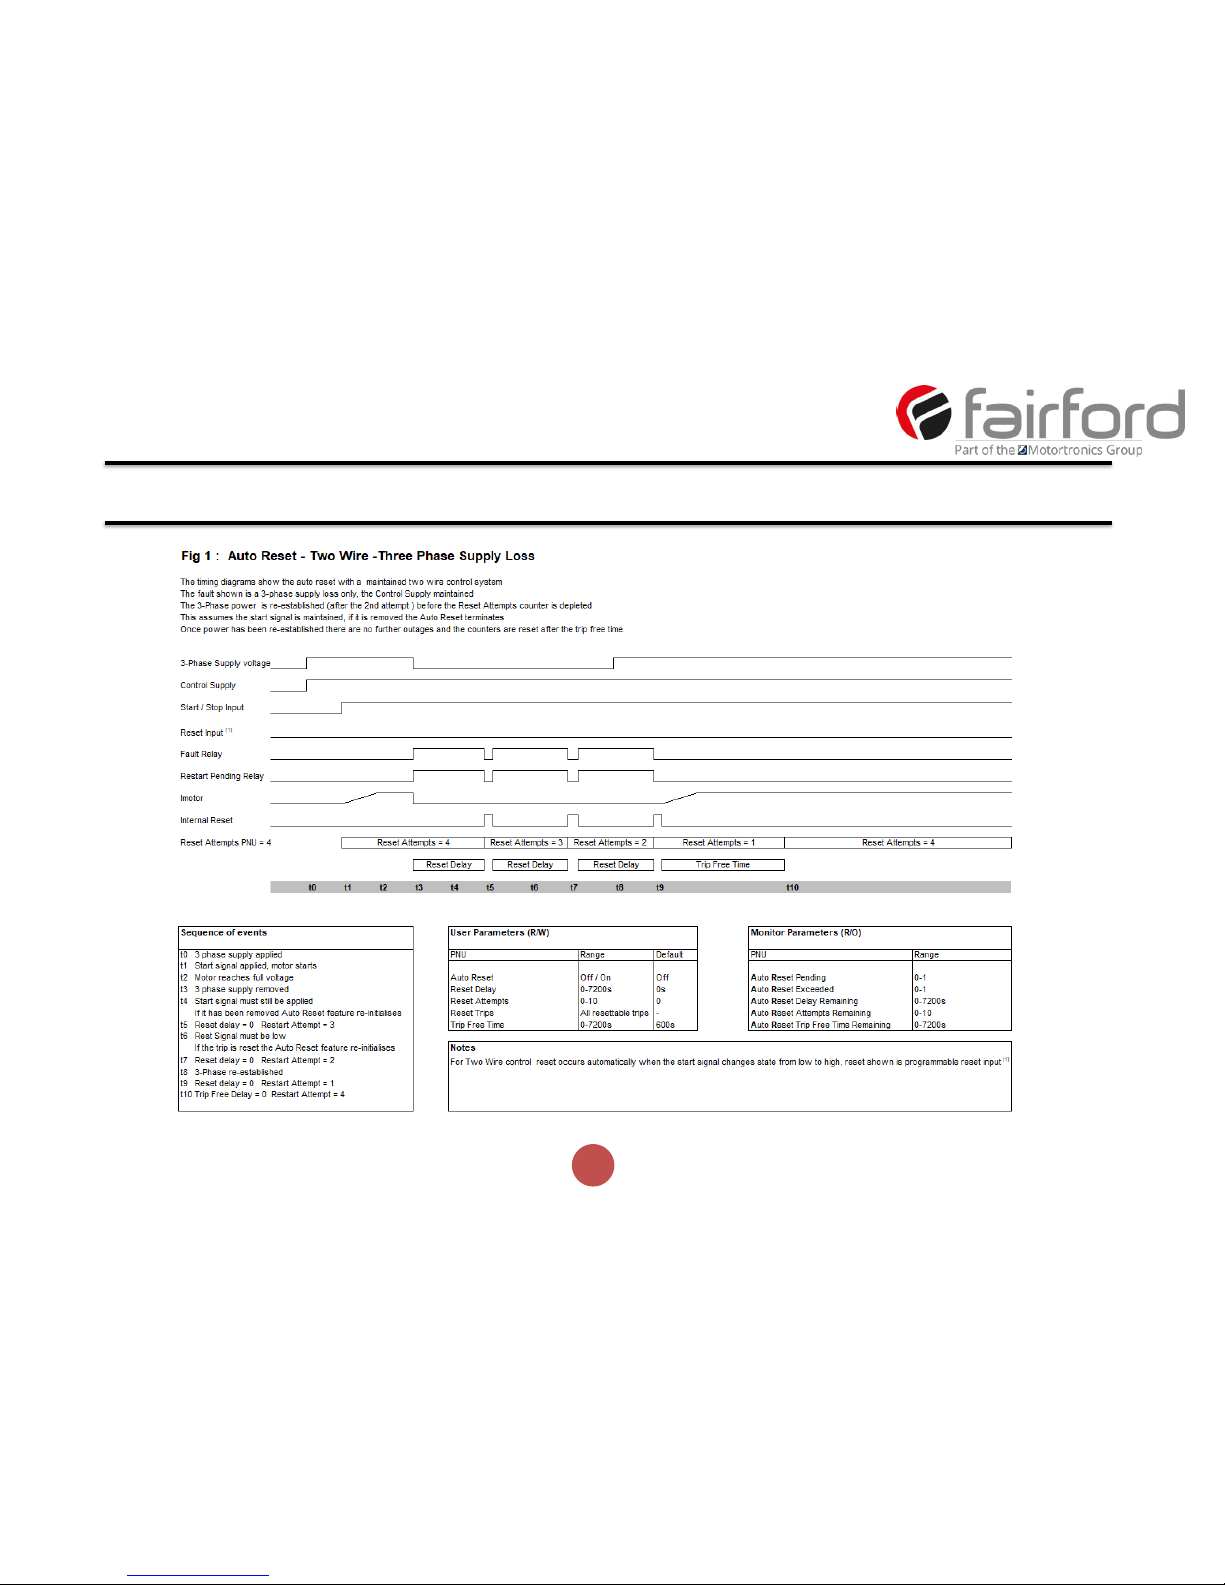
55
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset Function (continued)
Page 57
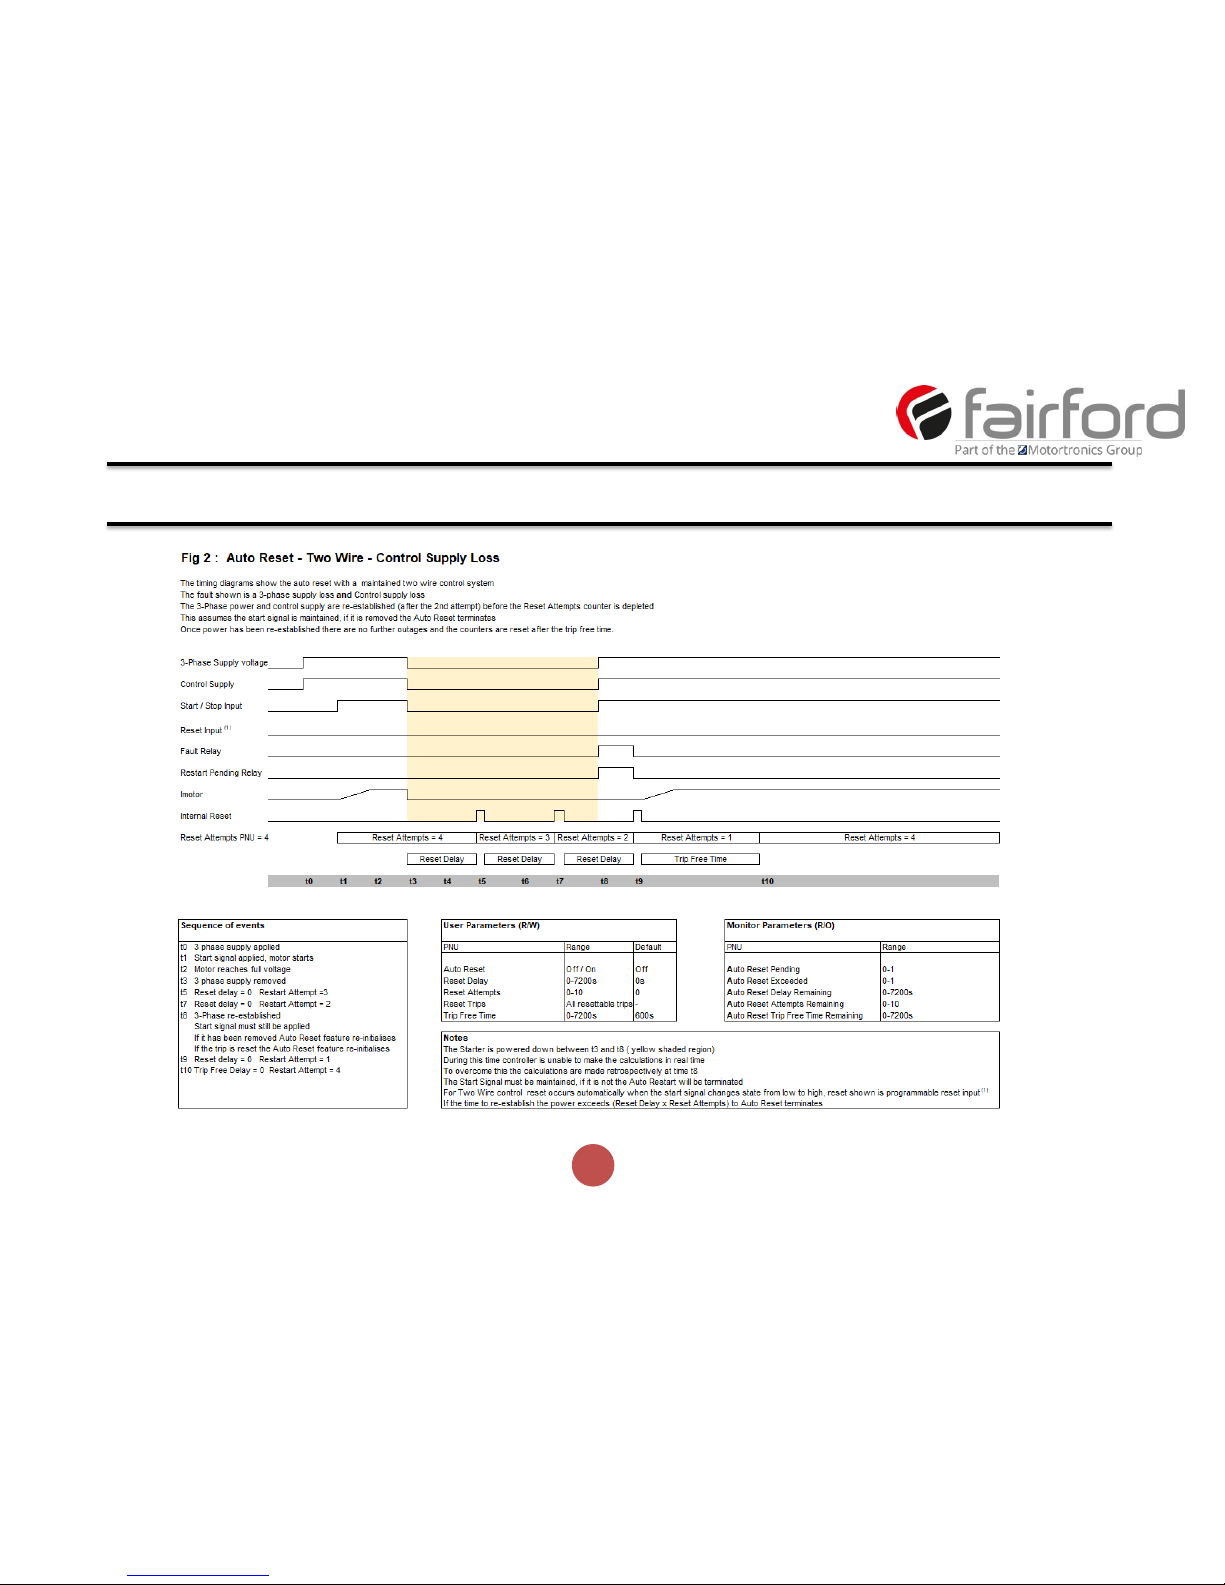
56
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset Function (continued)
Page 58
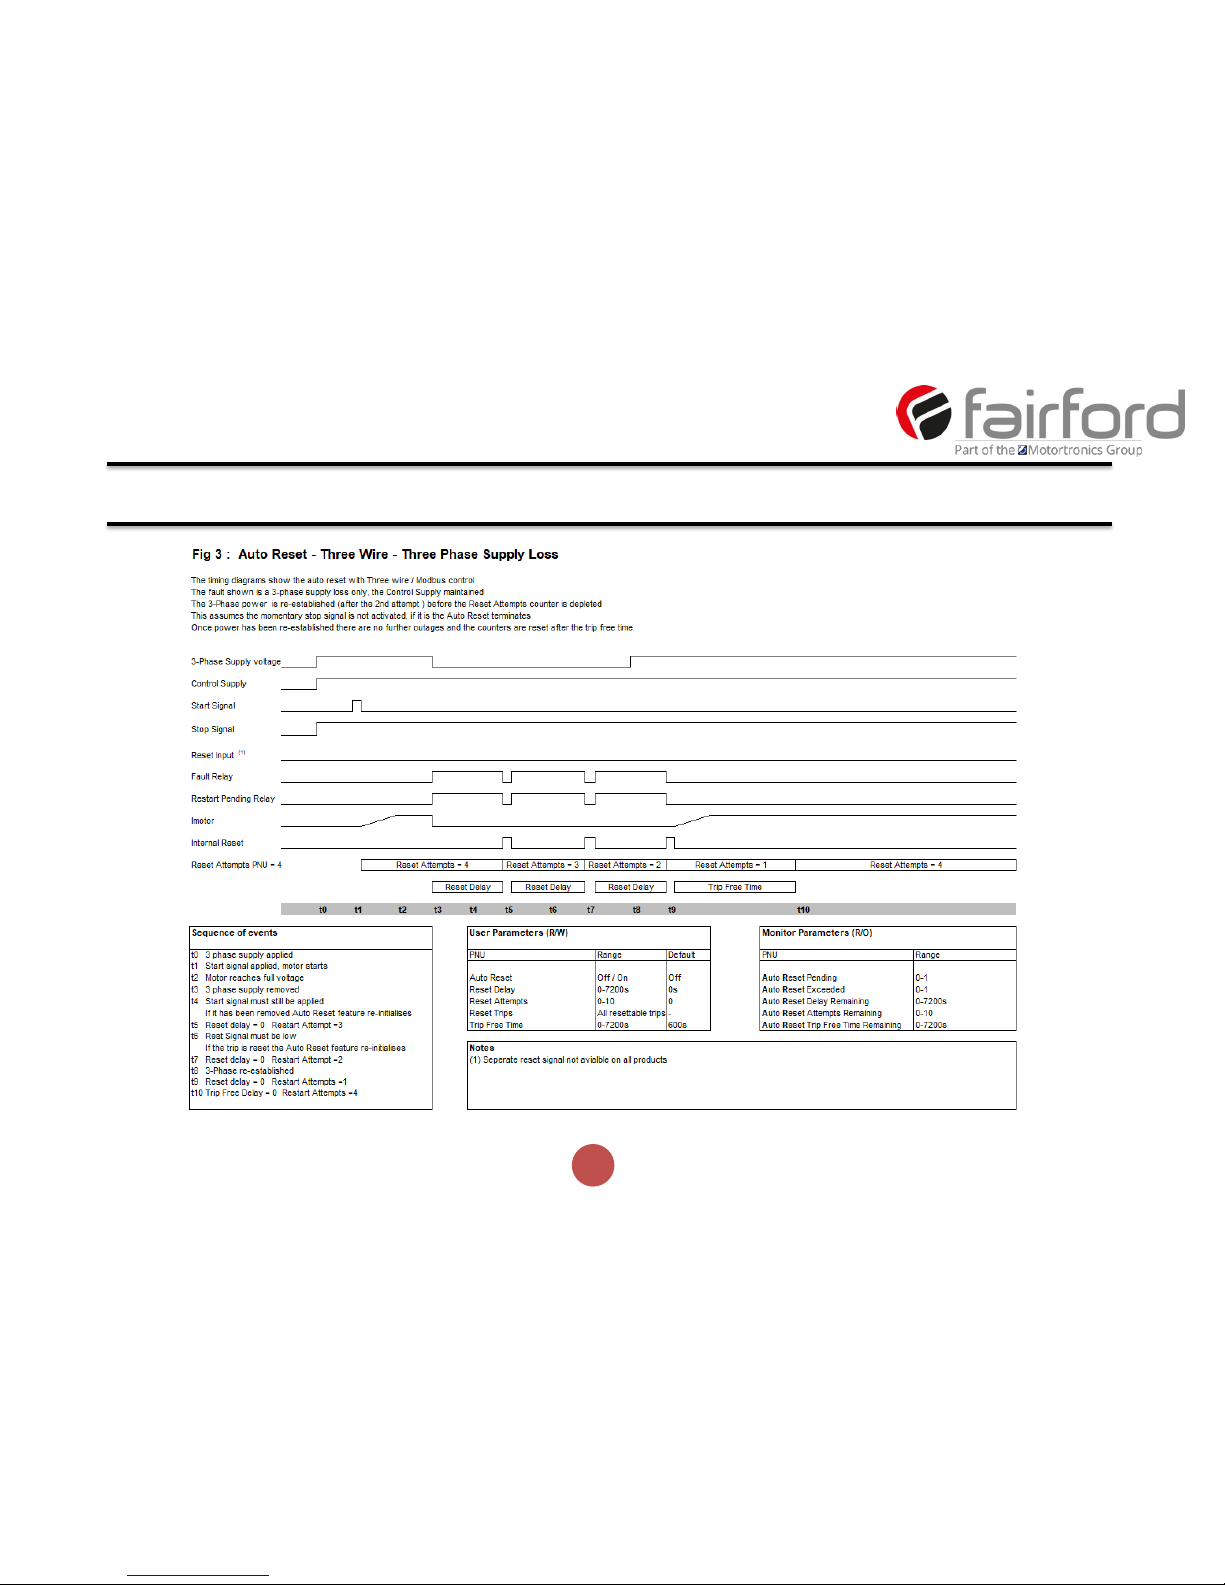
57
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset Function (continued)
Page 59
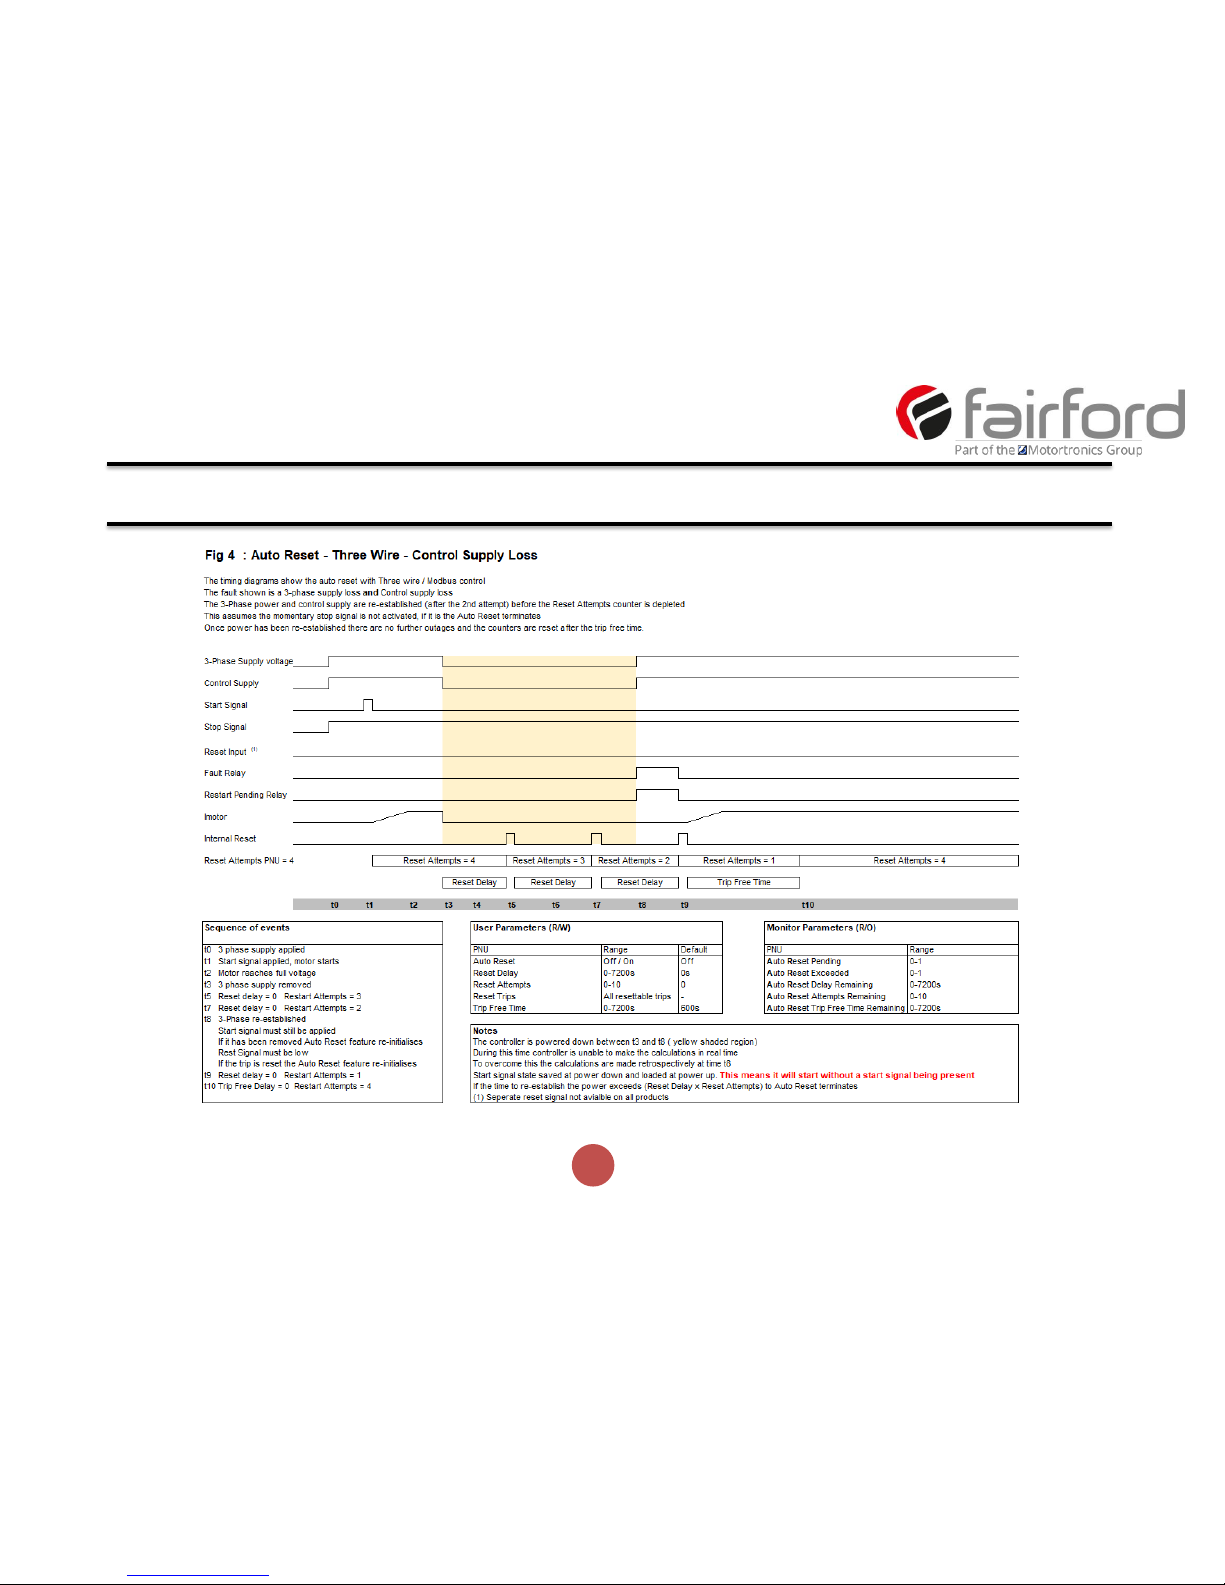
58
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset Function (continued)
Page 60
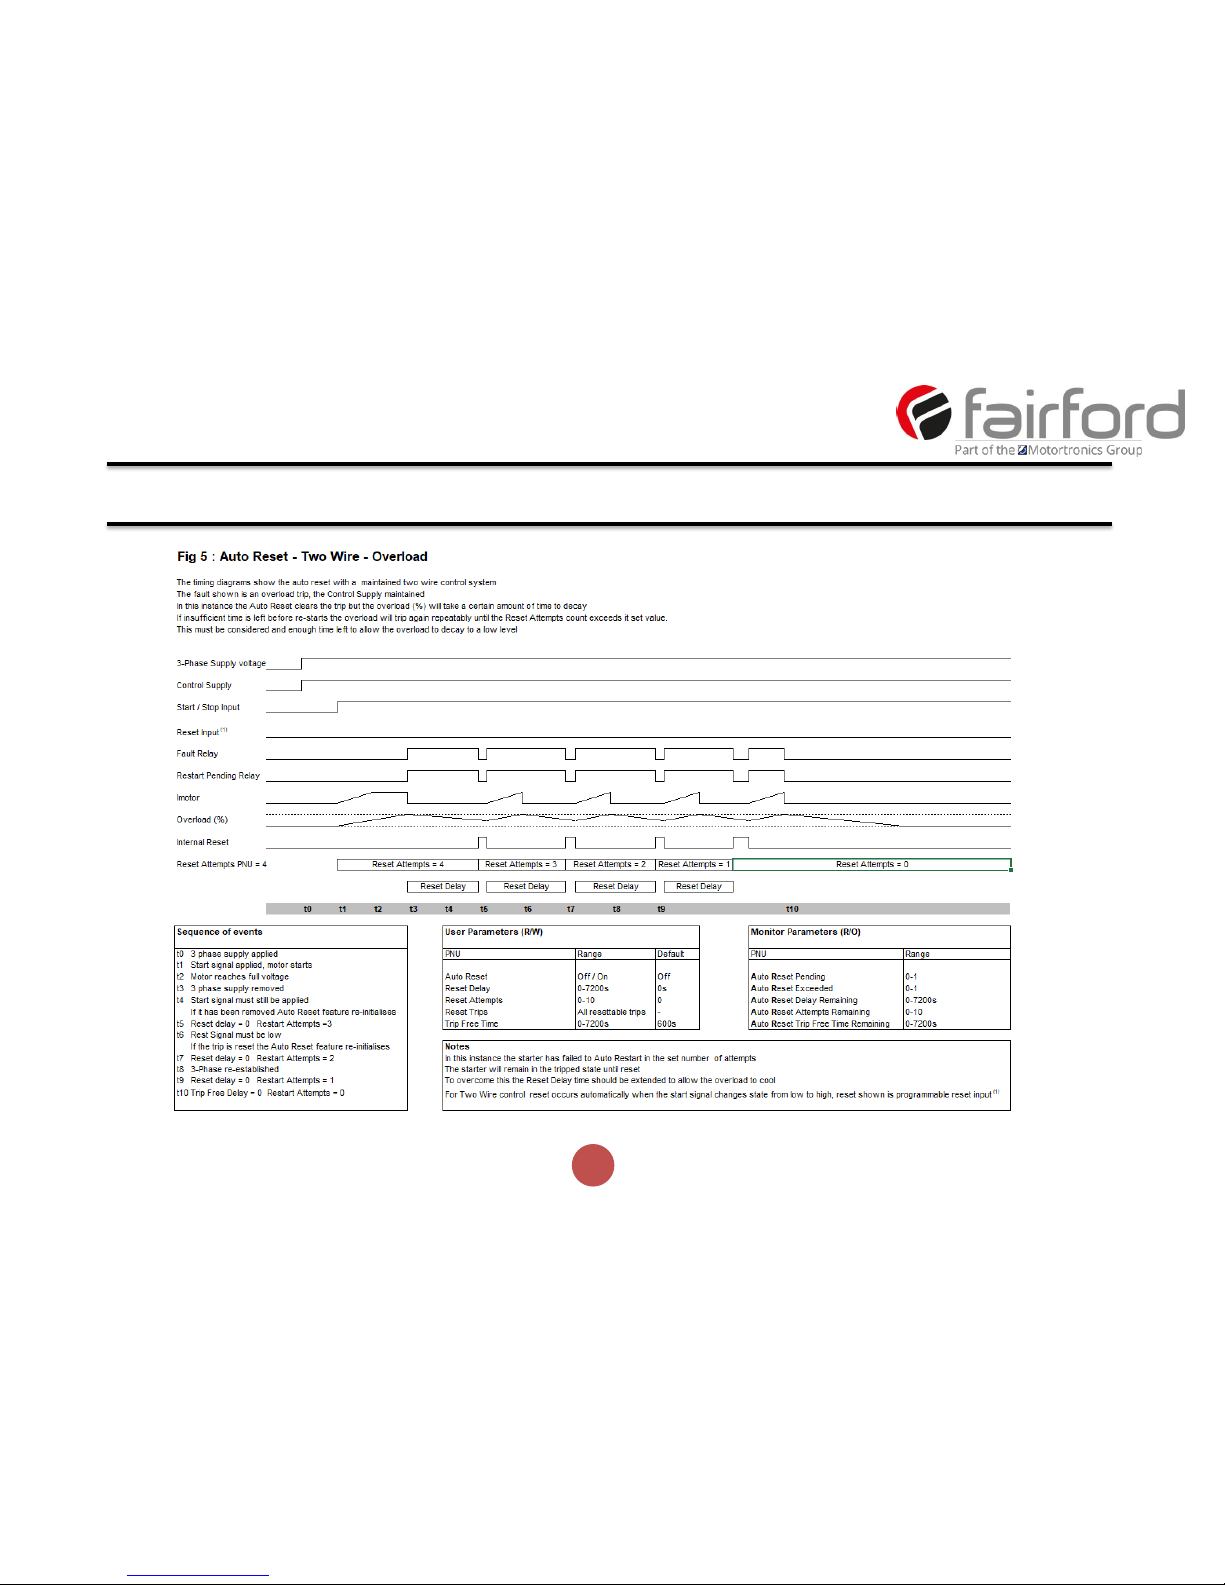
59
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Auto Reset Function (continued)
Page 61
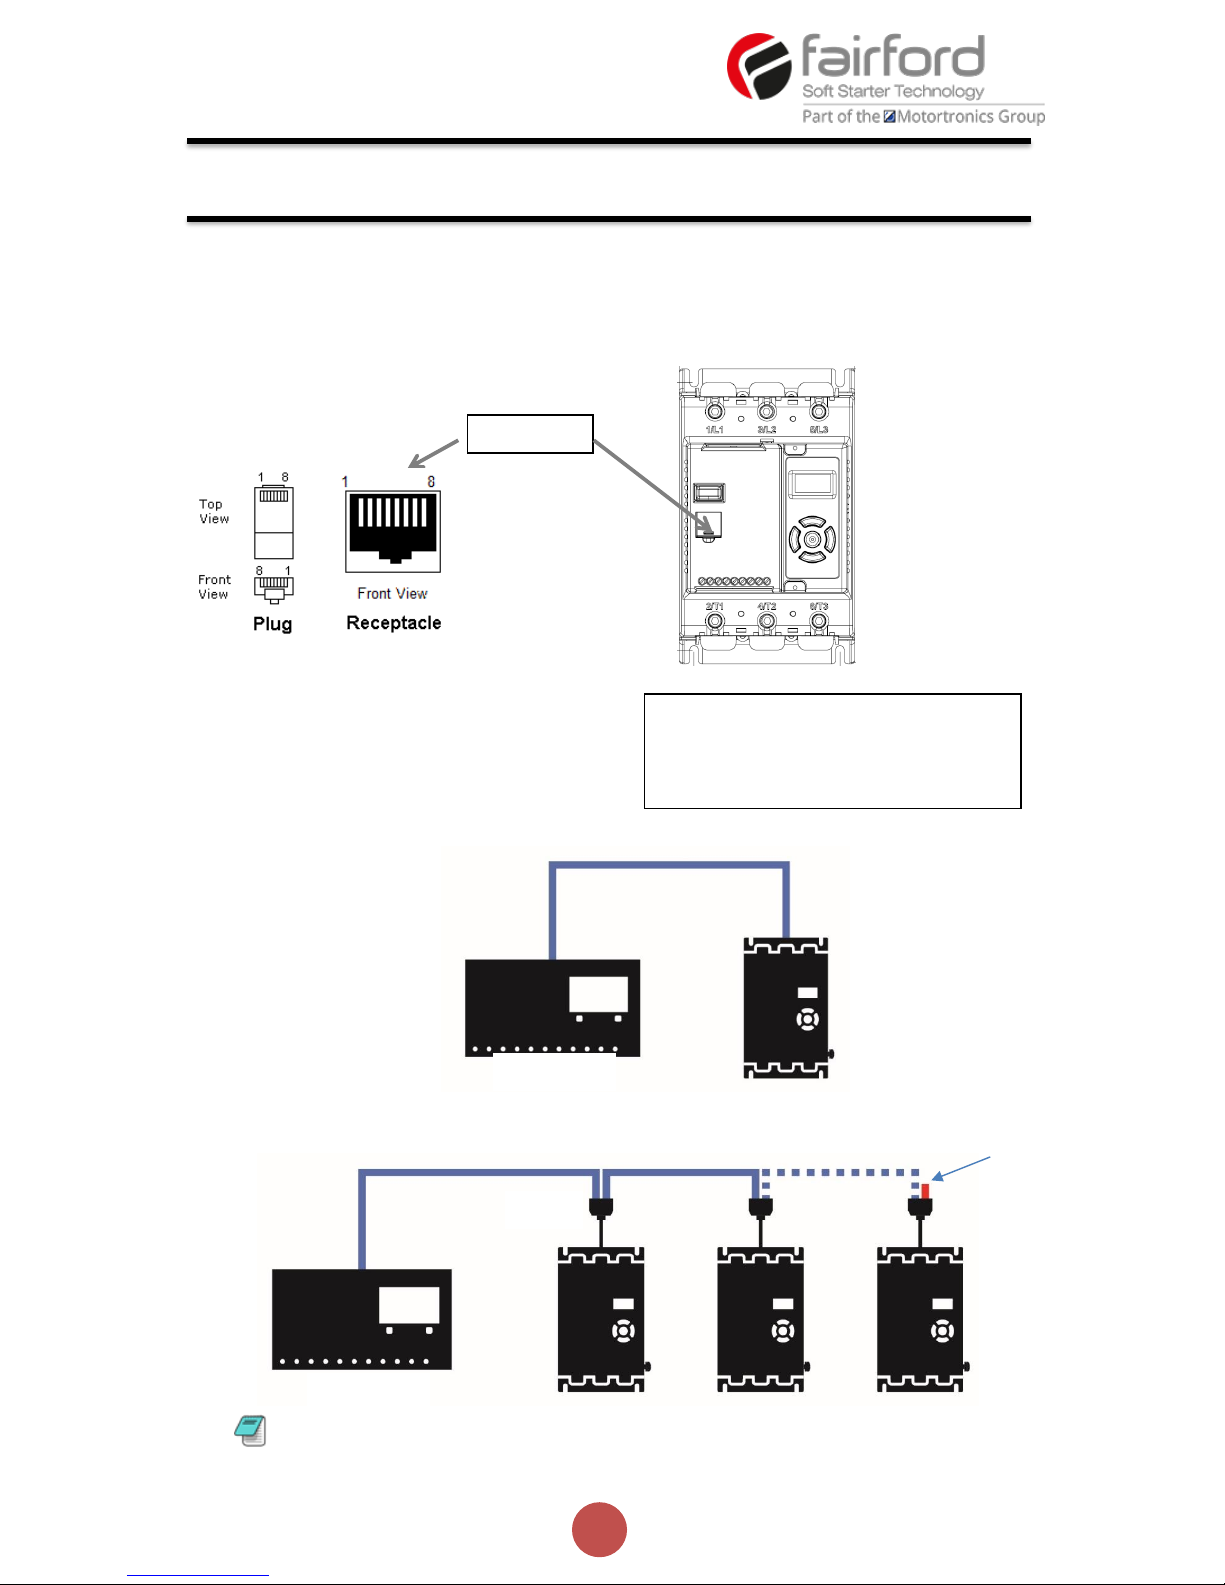
60
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
CBL-035 Terminator
(last unit only)
*Warning: To avoid damage to the
unit or to the RS-485 master, do NOT
connect to these pins!
Modbus RTU Serial Communications
Modbus RTU Communications Interface
All agilityTM soft starts support Modbus RTU as standard. The RS-485 communications are
accessible from the RJ45 connector (see below).
1 :
Not connected
2: Not connected
3: Not connected
4: TXD1-B-OUT
5: TXD0-A-OUT
6: Reserved*
7: Reserved*
8: GND
Modbus RTU Connections
Single agilityTM RS-485 network
Multiple agilityTM RS-485 network
CBL-036
RJ45 Socket
Communication
PLC (Master)
PLC (Master)
The agilityTM units must have: a unique Modbus address on each unit
and identical Parity/Baud rate values on each unit
Page 62
61
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Modbus Communications Configuration
The Modbus communication settings may be configured from the Device menu:
Device >> Networks >> Modbus Network Settings >> Address (1 – 32)
Device >> Networks >> Modbus Network Settings >> Baud (9600 – 115200)
Device >> Networks >> Modbus Network Settings >> Parity (Odd / Even)
(Data bits = 8, Stop bits = 1)
The communication parameters should be set before connecting the Modbus master.
Transmission Modes
ASCII and RTU transmission modes are defined in the Modbus protocol specification. agilityTM
uses only the RTU mode for the message transmission.
Message Structure For RTU Mode
The Modbus RTU structure uses a master-slave system for message exchange. In the case of the
agilityTM system, it allows up to 32 slaves, and one master. Every message begins with the master
making a request to a slave, which responds to the master in a defined structure. In both
messages (request and answer), the used structure is the same:
• Address, Function Code, Data and CRC.
Master (request message):
Address
(1 byte)
Function
(1 byte)
Request Data (n
bytes)
CRC
(2 bytes)
Slave (response message):
Address
(1 byte)
Function
(1 byte)
Response Data
(n bytes)
CRC
(2 bytes)
Address
The master initiates the communication by sending a byte with the address of the destination
slave. When responding, the slave also initiates the message with its own address. Broadcast to
address 0 (zero) is not supported.
Function Code
This field contains a single byte, where the master specifies the type of service or function
requested to the slave (reading, writing, etc.). According to the protocol, each function is used to
access a specific type of data.
Data Field
The format and contents of this field depend on the function used and the transmitted value.
Communication (continued)
Page 63
62
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Communication (continued)
CRC
The used method is the CRC-16 (Cyclic Redundancy Check). This field is formed by two bytes;
where first the least significant byte is transmitted (CRC-), and then the most significant (CRC+).
The CRC calculation form is described in the Modbus RTU protocol specification.
Supported Functions
Modbus RTU specification defines the functions used to access different types of data.
agilityTM parameters are defined as holding type registers.
For Modbus RTU/TCP Client devices that use Modicon style addressing, place a 4 as the high digit
followed by the Modbus address defined in the parameter mapping table. Note that agilityTM
Modbus addressing starts at zero; not 1 as some devices do.
agilityTM 32-bit parameters are High Word / Low Word in Modbus format.
The following services are available:
Read Holding Registers
Description: reading register blocks of holding register type (block R/W limited to 8
registers).
•
Function code: 03 example
Modbus Function 03 Transaction Table
Query
Response
Field
Hex Byte
Field
Hex Byte
Slave address
01
Slave address
01
Function
03
Function
03
Start address Hi
00
Byte count
02
Start address Lo
01
Data Hi
01
No of registers
00
Data Lo
2C
No of registers
01
CRC Lo
B8
CRC Lo
D5
CRC Hi
09
CRC Hi
CA
Page 64
63
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Write Single Register
Description: writing in a single register of the holding type.
•
Function code: 06 example
Modbus Function 06 Transaction Table
Query
Response
Field
Hex Byte
Field
Hex Byte
Slave address
01
Slave address
01
Function
06
Function
06
Address Hi
00
Address Hi
02
Address Lo
0C
Address Lo
0C
Data Hi
00
Data Hi
00
Data Lo
09
Data Lo
09
CRC Lo
48
CRC Lo
88
CRC Hi
0C
CRC Hi
77
Write Multiple Registers
Description: writing register blocks of holding register type (block R/W limited to 8 registers).
Function code: 16 example
Modbus Function 16 Transaction Table
Query
Response
Field
Hex Byte
Field
Hex Byte
Slave address
01
Slave address
01
Function
10
Function
10
Address Hi
00
Address Hi
00
Address Lo
01
Address Lo
01
# Words Hi
00
# Words Hi
00
# Words Lo
01
# Words Lo
01
# Bytes
02
CRC Lo
50
Data Hi
00
CRC Hi
09
Data Lo
02
CRC Lo
26
CRC Hi
40
Communication (continued)
Page 65
64
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
Memory Map
agilityTM Modbus communication is based on reading or writing equipment parameters from or
to the holding registers. The data addressing is zero offset, such that the parameter Modbus
address corresponds to the register number.
Modbus Address Memory Map
Parameter Modbus
Address
Modbus Data Address
Decimal
Hex
0000
0
0000h
0001
1
0001h
• • •
• • • • •
•
• • •
0128
128
0080h
• • •
• • • •
•
• • •
Message Timing
In the RTU mode there is no specific start or stop byte that marks the beginning or the end of a
message. Indication of when a new message begins or when it ends is achieved by the absence
of data transmission for a minimum period of 3.5 times the transmission time of a data byte.
Thus, in case a message is transmitted after this minimum time has elapsed; the network
elements will assume that the first received character represents the beginning of a new
message.
Modbus RTU Parameters
Page 66
65
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Unit
s
Detail
1
Cntrl
Mode
Selects the method for starting and
controlling the motor
Local : Control using the button on
the keypad
Remote : Control using the
terminals.
Modbus : Control via Modbus
network
0=Local,
1=Remote,
2=Modbus.
1
R/
W
Multiplier:
1
Divisor:1
Offset: 0
Min: 0
Max: 2
Default: 0
2
Initial
Volts
Percentage of the supply voltage
applied to motor at the beginning of
the soft start.
Increase to provide more torque If
the load fails to break away.
Decrease if the motor accelerates
too quickly.
1
R/W %
Multiplier:
100
Divisor:163
84
Offset: 0
Min: 1638
Max: 13107
Default:
3277
4
Start
Time
Time taken to soft start from the
"Initial Volts" to the end of the start
Normally set between 5 and 30
seconds.
Actual time to get to full voltage
depends on the "Limit Amps".
If set too long the motor can be at
speed before the end of the time set.
1
R/W s
Multiplier:
1
Divisor:1
Offset: 0
Min: 1
Max: 30
Default: 10
5
Stop
Time
The time taken to soft stop from full
voltage to the end of the stop
Normally set between 15 and 30
seconds.
Actual time to get to the final voltage
depends on the "Limit Amps".
If set too long the motor may reach
zero speed before the end of the
time set.
1
R/W s
Multiplier:
1
Divisor:1
Offset: 0
Min: 0
Max: 30
Default: 0
Modbus RTU Parameters (continued)
Page 67
66
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
6
Start
Delay
Time allowed for external contactors
to close.
Increase if contactors are driven by
buffer relays or motor trips on phase
loss when start signal applied
Decrease if response to start signal
needs to be improved
1
R/W
ms
Multiplier:
1
Divisor:1
Offset: 0
Min: 100
Max: 30000
Default:
160
7
Serial No
The device serial number stored at
the point of manufacture
4
R Multiplier:
1
Divisor:1
Offset: 0
Min: 0
Max: 255
Default: 0
11
Model
No
The device Model number stored at
the point of manufacture
1
R Multiplier:
1
Divisor:1
Offset: 0
Min: 101
Max: 113
Default:
101
14
Version
Software Version for the Main
control PCB
Software version recorded in log file
2
R Multiplier:
1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 68
67
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Word
s
Type Unit
s
Detail
16
Application
The Unit has numerous pre-set
applications built in as standard.
Select the application best suited to
the load.
The selected application will
automatically change several
parameters and functions.
Depending on the application
loaded the “Trip Class" may also
change
Refer to the separate 'applications
section' for more details
See Table 1
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 23
Default: 0
17
Trip Class
The trip class is a numeric value that
correlates the trip time with
overload level.
Select Trip class according to
application requirements
The trip time depends on the
selected "Trip Class" the duration of
the overload and the level of the
over current.
Refer to the Motor Overload 'cold'
trip curves given in the Guide.
When "Class 20" or "Class30" are
selected the Unit current rating (Unit
Amps) will be reduced to a lower
value (Rated Amps).
10=Class10,
20=Class20,
30=Class30.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 10
Max: 30
Default: 10
18
Motor
Amps
This should be set to the Full Load
Current shown on the motor plate
The overload works with multiples
of the set "Motor Amps"
Also referred to as Motor FLA
2
R/W
A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 0.1 x
PNU18
Max: 1 x
PNU20
Default: 1 x
PNU20
Modbus RTU Parameters (continued)
Page 69
68
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Word
s
Type Unit
s
Detail
20
Rated
Amps
Unit Class20 / Class30 Current
Rating
2 R A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 17000
Max: 66000
Default:
17000
22
Unit Amps
Unit Class10 Current Rating
2 R A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 17000
Max: 66000
Default:
17000
24
MotorState
Indicates the Unit Operating State
See Table 2
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
25
I rms
The RMS motor current
The average of the 3 phases.
This value is used for the current
Limit and overload features
2 R A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 0
Max: 24
Default: 0
Modbus RTU Parameters (continued)
Page 70
69
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Word
s
Type Unit
s
Detail
27
Overload
The Unit has an "Overload" function
that is an electronic equivalent to a
thermal overload.
Overload displays the overload
capacity which is a measure of how
close the Unit to tripping on
"Overload Trip"
When "Irms" is greater than the
"Overload Amps" the "Overload"
increases in accordance with the "Trip
Class".
When "Current Irms" is less than
"Overload Level" the "Overload"
decreases exponentially (if greater
than 50%)
When the "Overload" reaches 100%
the Unit will trip.
During situations when "Motor Amps"
is equal to "Unit Amps" the overload
will indicate 50%
1 R %
Multiplier: 100
Divisor:16384
Offset: 0
Min: 0
Max: 16384
Default: 0
During
situations
when "Motor
Amps" is equal
to "Unit Amps"
the overload
will indicate
50%
30
Frequenc
y
The frequency of the 3-phase supply
1 R Hz
Multiplier: 1
Divisor:1000
Offset: 0
Min: 45000
Max: 65000
Default: 0
31
Factory
Rst
Restores the Unit to the factory
defaults
0=Idle,
1=Active.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
Modbus RTU Parameters (continued)
Page 71
70
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Unit
s
Detail
32
Store
Param
Saves all Read /Write parameters to
non-volatile memory
Yes: Parameters are permanently
written
No : Parameters remain changed until
next power cycle
0=Idle,
1=Active.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
33
Save Log
Download the full log file on to the
USB stick
The Unit logs several parameters
during normal and fault conditions
Data is stored in CSV format. Please
send all downloaded files to Fairford
on request
0=Idle,
1=Active.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
34
Date
Enter current date
Date format can be set to either
dd/mm/yyyy or mm/dd/yyyy. Refer to
"Date format" parameter.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
35
Time
Allows the time to be changed to 'local'
time
By default the time is set to GMT
2
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 72
71
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
37
Rotation
Indicates the phase sequence of the
incoming supply.
RYB = ABC = L1-L2-L3
RBY = ACB = L1-L3-L2
0=------,
1=L1L2L3,
2=L1L3L2.
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 2
Default: 0
39
HS Temp C
The temperature of the internal Unit
heatsink.
The Unit will trip when the heatsink
temperature exceeds 80°C.
The internal cooling fans will turn on if
this temperature exceeds 40°C
1 R C
Multiplier: 1
Divisor:16
Offset: 0
Min: 0
Max: 65535
Default: 0
40
HS Temp F
The temperature of the internal Unit
heatsink.
The Unit will trip when the heatsink
temperature exceeds 176°C
The internal cooling fans will turn on if
this temperature exceeds 104°F
1 R F
Multiplier: 9
Divisor:80
Offset: 32
Min: 0
Max: 65535
Default: 0
41
I1 rms
The RMS current on phase L1
2 R A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 0
Max: 24
Default: 0
Modbus RTU Parameters (continued)
Page 73
72
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
43
I2 rms
The RMS current on phase L2
2 R A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 0
Max: 24
Default: 0
45
I3 rms
The RMS current on phase L3
2 R A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 0
Max: 24
Default: 0
47
Delay Angle
Internal firing delay angle in Degrees
Displayed for diagnostic purposes
1 R °
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 180
Default: 0
48
AGY100 Ver
The hardware version for display PCB
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 1
Modbus RTU Parameters (continued)
Page 74
73
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
49
Phase Loss
Detects for various issues when the
start signal is applied
Detects for input phase loss / input
phase relationship / motor side loss
Trip On: Trips if there is an input phase
loss / supply out of balance / motor
side loss
Trip Off: The Unit will attempt to run
although the operation may be erratic.
Operating with the Trip Off for
prolonged periods may result in SCR
failure
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
50
Overheat
Detects if the internal temperature
sensor has malfunctioned
Trip On: The Unit will trip if the
internal temperature sensor
malfunctions
Trip Off : The Unit will continue to
operate even if the temperature sensor
has malfunctioned.
Operating with the Trip Off for
prolonged periods may result in SCR
failure
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
51
Ph / SCR
Detects for various issues when
"Starting" or " Stopping"
Detects for input phase loss / Output
phase loss / SCR misfire
Trip On: Trips if there is an input phase
loss / motor side phase loss / SCR
misfire
Trip Off: The Unit will attempt to run
although the operation may be erratic.
Operating with the Trip Off for
prolonged periods may result in SCR
failure
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
Modbus RTU Parameters (continued)
Page 75
74
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
58
I Low
This can be used to detect if the motor
is running lightly loaded.
Trip On: The Unit will trip. This feature
is not active during soft start and soft
stop.
Trip Off: The Unit will continue to
operate regardless of motor current
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
59
I Limit Start
Selects trip or continue if the current
limit has been active for too long
Trip On: The Unit will trip
Trip Off: The start will continue
regardless of the motor current level
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
60
Overload
The Unit has an "Overload" function
that is an electronic equivalent to a
thermal overload.
Trip On: The Unit will trip when the
"Overload" capacity (Modbus PNU 27)
exceeds 100%
Trip Off: The Unit will continue to
operate regardless of motor current
level
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
61
Shearpin
The Shearpin is an electronic
equivalent of a mechanical Shearpin
Trip On: The Unit will trip. This feature
is not active during soft start and soft
stop.
Trip Off: The Unit will continue to
operate regardless of motor current
level
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
Modbus RTU Parameters (continued)
Page 76
75
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
64
Comms
Detects if the communications bus has
failed or become inactive.
To keep the bus active there must be
at least one Modbus read or write (any
PNU) during the "Comms Time” period
(ModbusPNU 147)
Trip On: Communication trip enabled.
Trip Off: External Trip is disabled
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
66
Remote
For safety reasons the Unit will trip
during some operations if the remote
start signal is active
Trip On: Trips if the remote start signal
is active when the Unit is powered up
or a reset is applied.
Trip Off: The Unit will not trip and may
start unexpectedly if the start signal is
accidently left active.
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
67
CT Fault
Detects if the internal current sensors
have failed or reading a very low level.
Trip On: The Unit will trip if the
internal current sensors fail or the
current measured falls to a very low
level
Trip Off: Will continue to operate even
if the sensor has failed. Measurements
and overload protection may be
affected
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
68
Operation 1
Detects if the Control Board has failed
to operate normally
Trip On: System Trip enabled.
Trip Off: System Trip disabled.
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
Modbus RTU Parameters (continued)
Page 77
76
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
69
Limit Amps
The current in Amps at which the soft
Start ramp is held.
Normally set to 350% of motor FLC.
Increase if motor fails to accelerate at
required rate
The "Limit Amps" will affect actual time
to start.
If set too low the motor may not
accelerate to full speed.
2
R/W
A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 0.5 x
PNU18
Max: 5 x
PNU20
Default: 3.5 x
PNU20
71
Limit Time
The maximum time allowed for the
current limit.
If the current limit is still active at the
end of this period the Unit will either
'Trip' or 'continue'
1
R/W
s
Multiplier: 1
Divisor:1
Offset: 0
Min: 1
Max: 60
Default: 30
72
Boot Ver
Software Version for the Bootloader
2
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
74
Cntrl Funct
Allows the Digital inputs to be mapped
to different functions
Cntrl Mode must be set to "Remote"
Two Wire: D1 = Start (Reset) / Stop
Three Wire: D1 = Start (Reset) D2 =
Stop
D2 Reset , D2 Hold , D2 Enable , D2
Fire : D1= Start /Stop, D2
programmed as shown
0=Three
Wire, 1=Two
Wire, 2=D2
Reset, 3=D2
Hold, 4=D2
Enable, 5=D2
Fire.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 5
Default: 0
Modbus RTU Parameters (continued)
Page 78
77
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
75
Op Mode
Allows the unit to operate with a single
phase motor
3 phase: Set to control a three phase
motor
1 Phase: Set to control a single phase
motor
0=3 phase ,
1=1 phase.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
77
Trip 0
Displays the last Fault trip
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
78
Trip 1
Displays the last Fault trip -1
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
79
Trip 2
Displays the last Fault trip -2
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 79
78
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
80
Trip 3
Displays the last Fault trip -3
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
81
Trip 4
Displays the last Fault trip -4
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
82
Trip 5
Displays the last Fault trip -5
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
83
Trip 6
Displays the last Fault trip -6
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 80
79
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
84
Trip 7
Displays the last Fault trip -7
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
85
Trip 8
Displays the last Fault trip -8
See Table 3
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
86
MenuBuild
Menu Version
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
87
Kick Level
Percentage of the supply voltage
applied to the motor during the ‘kick'
period
Increase to provide more torque If the
load fails to break away.
Decrease if the motor accelerates too
quickly.
1
R/W
%
Multiplier:
100
Divisor:16384
Offset: 0
Min: 3277
Max: 13107
Default: 9830
Modbus RTU Parameters (continued)
Page 81
80
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
88
Kick Time
Time that the torque pulse is applied to
load
Increase to provide more torque If the
load fails to break away.
Decrease if the motor accelerates too
quickly.
1
R/W
ms
Multiplier: 1
Divisor:1
Offset: 0
Min: 100
Max: 2000
Default: 100
89
Kick Start
Applies a short duration torque pulse
to dislodge 'sticky' loads
On: The torque pulse is applied at
start-up when complete the torque
drops to the "Initial Volts"
Off: The initial starting torque is
defined by the "Initial Volts"
0=Off, 1=On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
90
To USB
Allows the user to save parameters
Downloads the parameters from the
Unit to the USB drive
Data is stored in CSV format.
0=Idle,
1=Active.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
91
From USB
Allows the user to load parameters
stored on a USB flash drive
Uploads the parameters from the USB
drive to the Unit
Data is stored in CSV format.
0=Idle,
1=Active.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
Modbus RTU Parameters (continued)
Page 82
81
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
94
I Start
Displays the peak current during the
last start.
1 R A
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 528
Default: 0
95
T Start
Displays the time of the last start
1 R s
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 90
Default: 0
96
I Stop
Displays the peak current during the
last stop.
1 R A
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 528
Default: 0
97
T Stop
Displays the time of the last stop
1 R s
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 90
Default: 0
Modbus RTU Parameters (continued)
Page 83
82
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
98
Total
Events
The total number of events that have
been recorded in the log file
2
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
103
AGY200 Ver
The hardware version for Main PCB
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 1
104
AGY300 Ver
The hardware version for Power PCB
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 1
106
Total Uc On
The total number times the start
command has been applied
2
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 84
83
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
109
Operation 2
Detects if the Control Board has failed
to operate normally
Trip On: System Trip enabled.
Trip Off: System Trip disabled.
0=Trip Off,
1=Trip On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
110
Reserved
No user function
114
Shear Amps
The current in Amps that will cause a
"Shear Trip"
A trip will occur if the motor current is
greater than the "Shear Amps" for the
"Shear Time"
2
R/W
A
Multiplier: 1
Divisor:1000
Offset: 0
Min: 1 x
PNU18
Max: 5 x
PNU22
Default: 3.5 x
PNU18
116
Shear TIme
The trip time for the Shearpin trip
A trip will occur if the motor current is
greater than the "Shear Amps" for the
"Shear Time"
1
R/W
s
Multiplier: 1
Divisor:1
Offset: 0
Min: 1
Max: 10
Default: 1
Modbus RTU Parameters (continued)
Page 85
84
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
119
Modbus
Enable
Enable using Modbus
On: The unit is enabled
Off: The unit is disabled
0=Off, 1=On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
120
Modbus
Start
Start / Stop using Modbus
On: Starts the Unit
Off: Stops or Soft stops the Unit
0=Off, 1=On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
121
Modbus
Reset
Reset using Modbus
On: The initial state required for a
reset.
Off: The final state required for a
reset.
To reset pulse high and then low
0=Off, 1=On.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
143
Fire Mode
A special feature that allows the Unit to
operate with ALL of the trips OFF.
Set " Cntrl Funct" to "D2 Fire Mode”,
Enabled when D2 is high
Although the unit will keep running in
this mode it may become damaged.
In some instances the damage may
inhibit a subsequent starts
This is only to be used in an emergency
0=Off, 1=On.
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
Modbus RTU Parameters (continued)
Page 86
85
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
145
TempUnit
Selects °C or °F for displayed
temperatures
°C: All displayed temperatures are °C
°F: All displayed temperatures are °F
0=°C, 1=°F.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 0
146
Disp Time
Time for backlight on display
After the period set the back light on
the screen will turn off
To reactivate touch screen anywhere.
To disable set to 0
1
R/W
s
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 7200
Default: 60
147
CommsTim
e
Communications trip Timeout period
To prevent a 'Communications Trip' (If
enabled) the bus must be kept active.
To keep the bus active there must be
at least one Modbus read or write (any
PNU) during the "Timeout ms” period
1
R/W
ms
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 60000
Default: 5000
148
Address
Sets the Modbus station number
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 1
Max: 32
Default: 1
Modbus RTU Parameters (continued)
Page 87
86
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
149
Parity
Sets the serial communications parity
bit
The available parity options are None
Even Odd
Also sets the stop bits. No parity uses 2
stop bits. Odd or even parity uses 1
stop bit
0=Odd,
1=Even.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
150
Baud
Sets the serial communications baud
rate
The available baud rates are 9600,
19200, 38400, 57600 or 115200
0=9600
baud,
1=19200
baud,
2=38400
baud,
3=57600
baud,
4=115200
baud.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 2
Default: 1
151
DateFormat
Allows the date format to be changed
dd/mm/yy or mm/dd/yy or yy/mm/dd
0=dd/mm/yy,
1=mm/dd/yy,
2=yy/mm/dd.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 2
Default: 1
153
AGY400 Ver
Displays the hardware version for the
temperature sense PCB
1
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 1
Modbus RTU Parameters (continued)
Page 88
87
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
154
RelayFunct
Allows the n/c relay (21 -22) to be
reconfigured
Available options are 22 = TOR or
22 = ERR
0=22 = TOR,
1=22 = ERR.
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 1
Default: 1
155
Reserved
No user function
157
Window
View
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
158
Window
Code
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 89
88
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
159
Reserved
No user function
160
Patch Addr
1
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
161
Patch Addr
2
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
162
Patch Addr
3
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 90
89
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
163
Patch Addr
4
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
164
Patch Addr
5
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
165
Patch Addr
6
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
166
Patch Addr
7
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 91
90
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
167
Patch Addr
8
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
168
Patch Addr
9
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
169
Patch Addr
10
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
170
Patch Addr
11
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 92
91
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
171
Patch Addr
12
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
172
Patch Addr
13
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
173
Patch Addr
14
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
174
Patch Addr
15
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 93
92
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
175
Patch Addr
16
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
176
Window 1
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
177
Window 2
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
178
Window 3
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 94
93
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
179
Window 4
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
180
Window 5
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
181
Window 6
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
182
Window 7
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 95
94
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
183
Window 8
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
184
Window 9
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
185
Window 10
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
186
Window 11
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 96
95
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
187
Window 12
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
188
Window 13
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
189
Window 14
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
190
Window 15
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 97
96
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
191
Window 16
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
192
Window 17
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
193
Window 18
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
194
Window 19
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 98
97
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
195
Window 20
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
196
Window 21
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
197
Window 22
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
198
Window 23
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 99
98
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
199
Window 24
Used to arrange the Modbus
Parameters into Groups
Refer to 'Special Modbus parameters'
document for more details
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
200
Total Us On
The total number of times the unit has
been powered up.
The unit is powered up by applying a
voltage to Uc
Uc will be 24V or 110V / 230V
depending on configuration
2
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
202
Total Us Off
The total number of times the unit has
been powered down.
The unit is powered down by removing
the voltage at Uc
Uc will be 24V or 110V / 230V
depending on configuration
2
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
204
Total Runs
The total number of times the unit as
successfully got to the "Running" State
The Running state is active when the
unit is operating at full voltage.
When operating at full voltage the
internal bypass relays are closed.
2
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
Modbus RTU Parameters (continued)
Page 100
99
agility Series User Manual
MAN-AGY-001. Version 06. 03/01/2019
PNU
Name
Description
Options
Words
Type
Units
Detail
206
Total Stops
The total number of successful stops /
soft stops
2
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
210
Total Trips
The total number of trips
2
R Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default: 0
211
Reserved
Multiplier:
Divisor:
Offset:
Min:
Max:
Default:
212
Diagnostic
1
Used for diagnostic purposes only
1
R/W
Multiplier: 1
Divisor:1
Offset: 0
Min: 0
Max: 65535
Default:
65535
Modbus RTU Parameters (continued)
 Loading...