

Page 1
170.IU0.XKC.0C1 05-02
r USER MANUAL
Xkc-01-C0.P65 5/29/02, 11:58 AM1
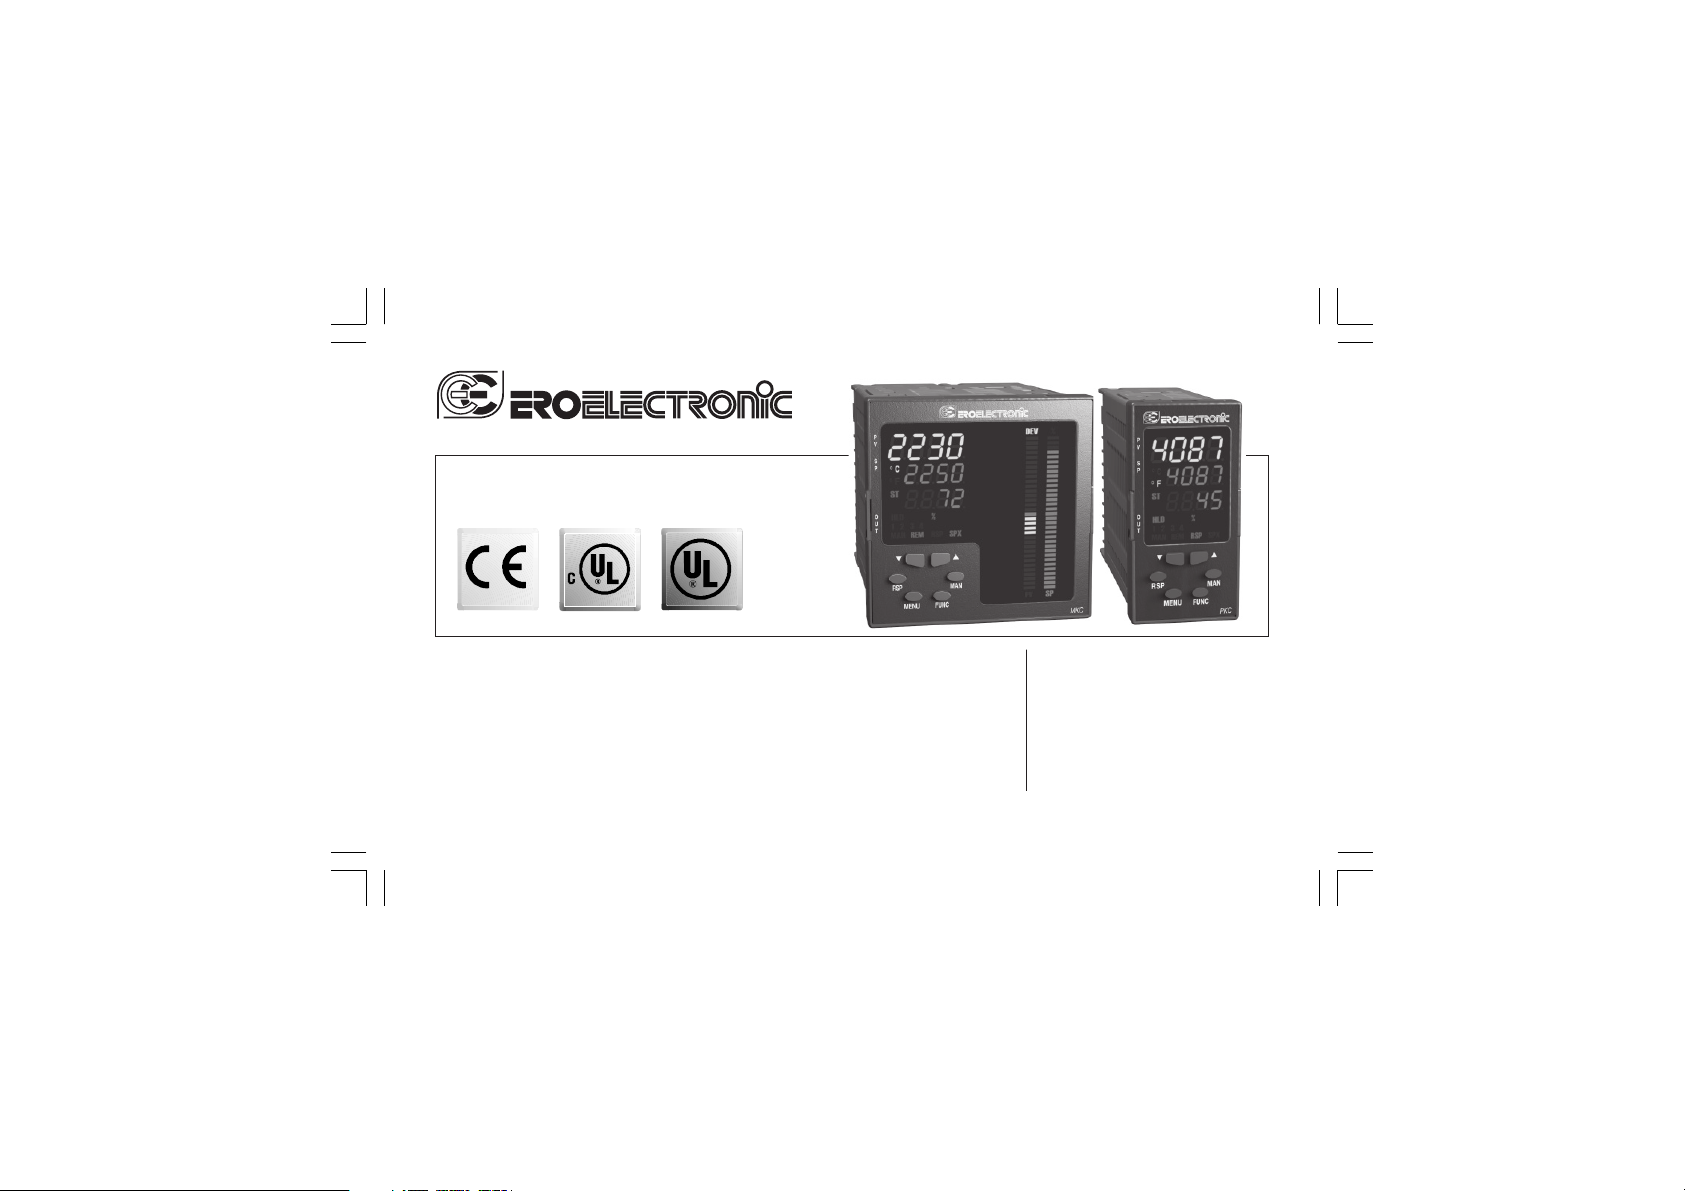
PKC
MKC
Page 2
Xkc-01-C0.P65 5/29/02, 11:58 AM2
Page 3
INDEX
MOUNTING REQUIREMENTS ................................................. 1
OUTLINE AND CUT OUT DIMENSIONS ................................. 2
CONNECTION DIAGRAMS ...................................................... 4
PRELIMINARY HARDWARE SETTINGS ............................... 17
SECURITY CODE SETTING MODE ...................................... 22
RUN TIME AND CONFIGURATION MODE ........................... 25
General notes about graphic symbols .............................. 25
Keyboard description ....................................................... 25
CONFIGURATION MODE ...................................................... 27
RUN TIME MODE ................................................................... 62
Display function ................................................................ 62
Indicators ......................................................................... 64
Bargraph description ........................................................ 65
OUT failure detection function (OFD) .............................. 66
Direct access to the set point ........................................... 66
Manual function ................................................................ 67
Serial link ......................................................................... 68
Lamp test ......................................................................... 69
SMART function ............................................................... 69
Hold function .................................................................... 70
Parameter protection ....................................................... 70
RUN TIME PARAMETER MODIFICATION ............................ 71
Xkc-01-C0.P65 5/29/02, 11:58 AM3
ERROR MESSAGES .............................................................. 97
GENERAL INFORMATIONS ................................................ 103
MAINTENANCE .................................................................... 112
DEFAULT PARAMETERS .................................................... A.1
ALPHANUMERIC INDEX OF THE
DISPLAY INDICATION ......................................................... B.1
CODING ................................................................................ B.7
Page 4
Xkc-01-C0.P65 5/29/02, 11:58 AM4
Page 5
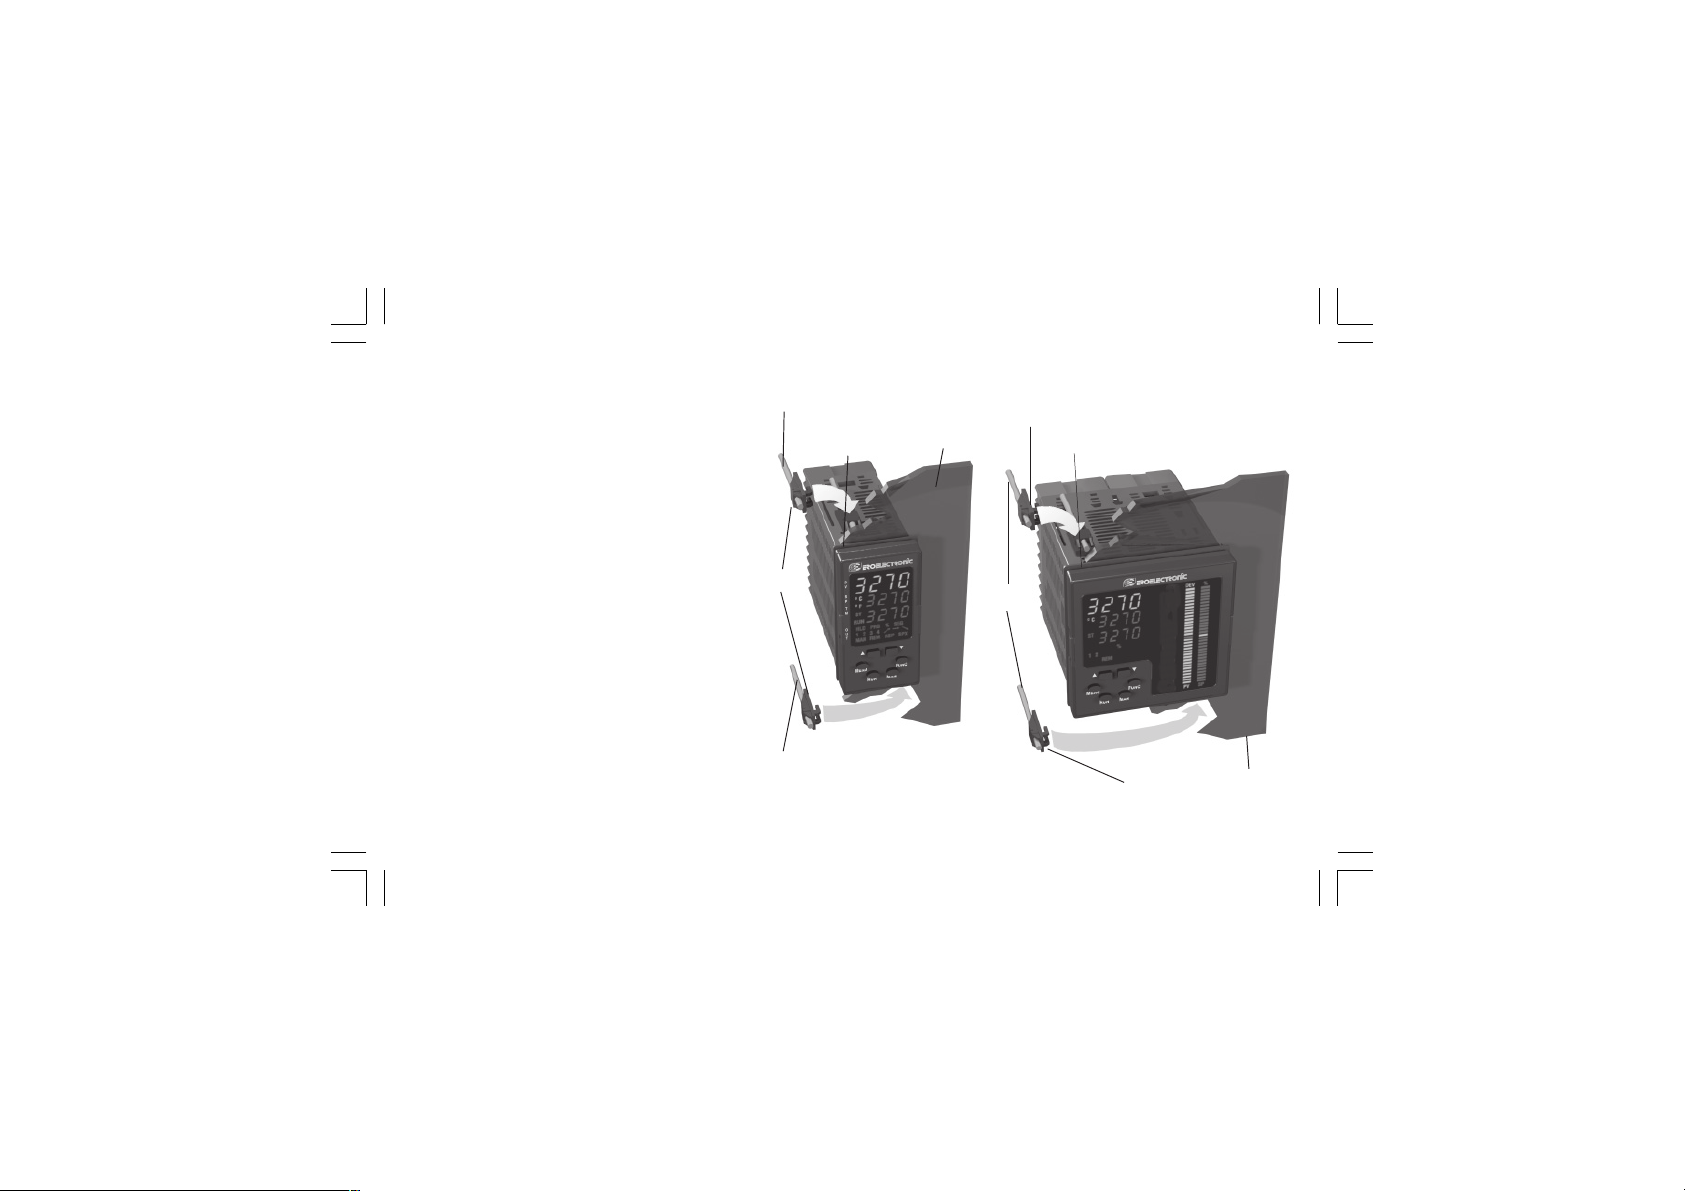
MOUNTING REQUIREMENTS
Select a location, for instrument mounting, where
minimum vibrations are present and the ambient
temperature is within 0 and 50 °C (32 and
122 °F).
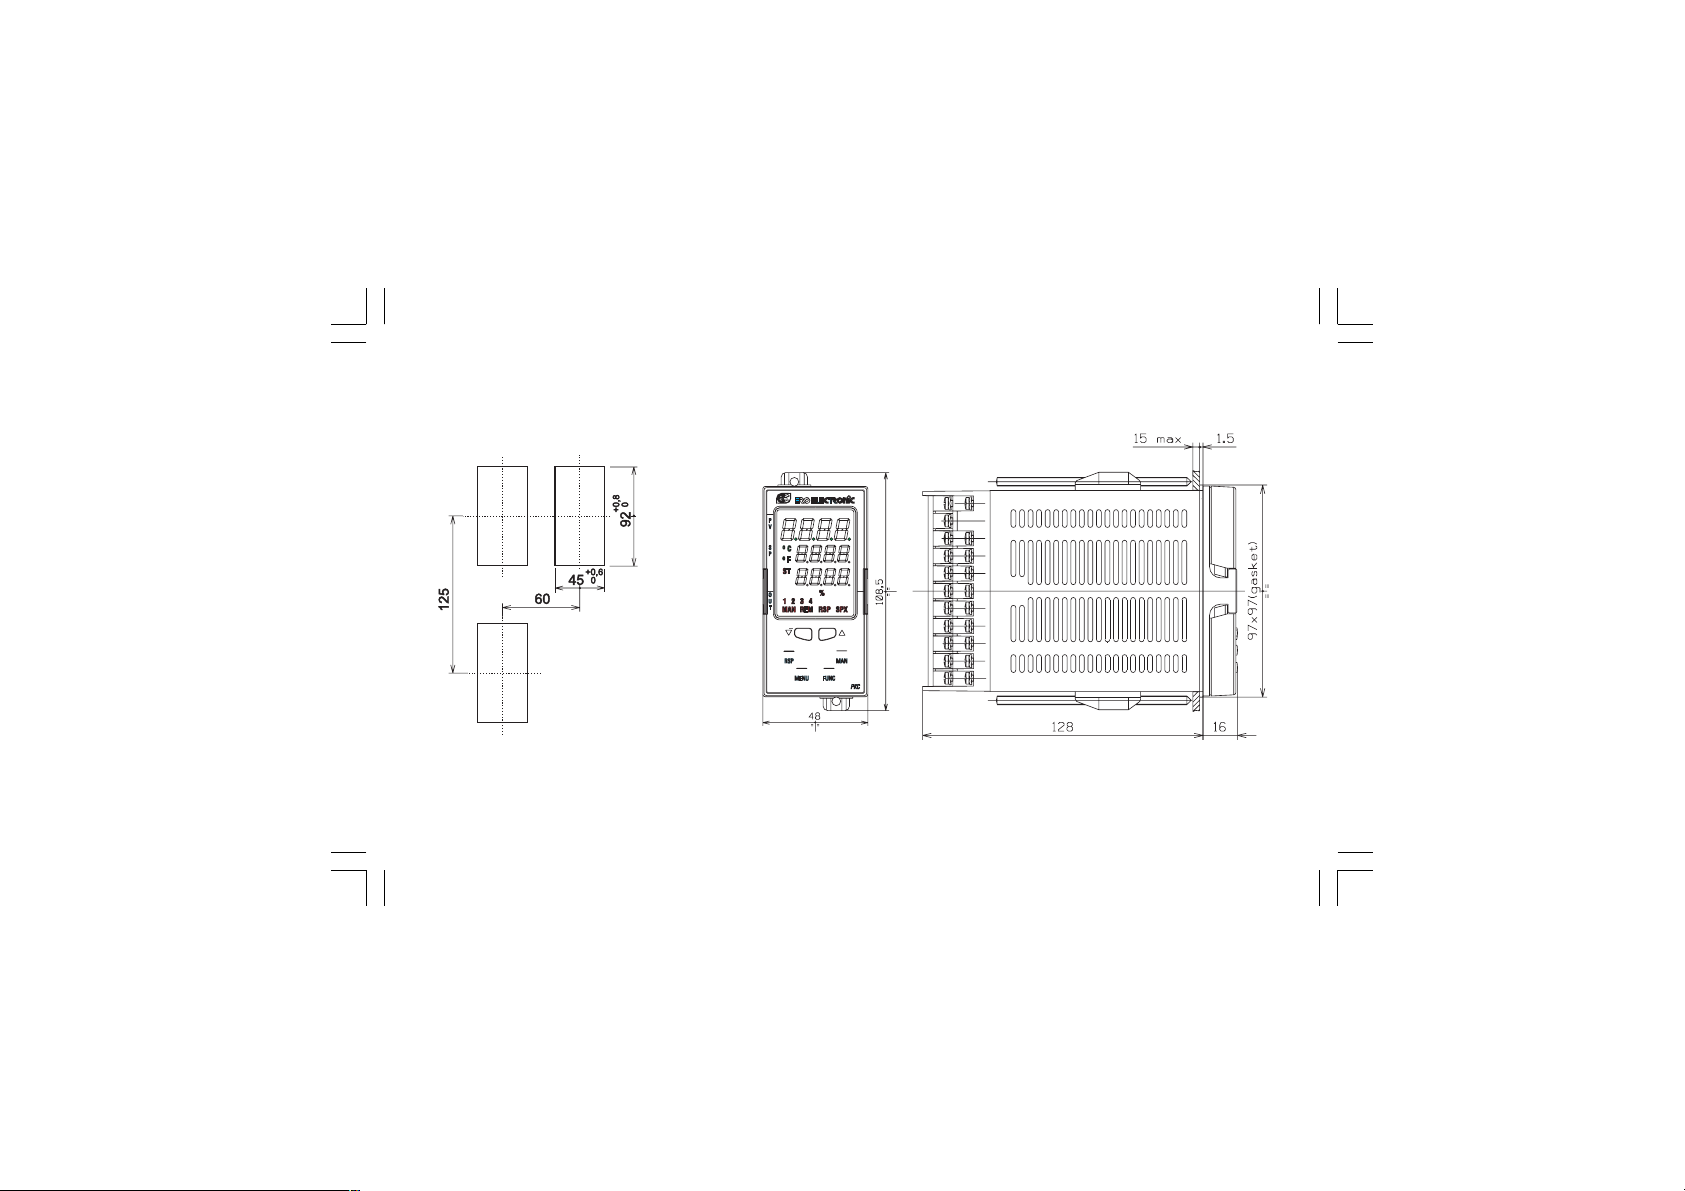
The instrument can be mounted on a panel up to
15 mm thick with a cutout of 92 x 45 mm (PKC) or
92 x 92 (MKC).
For outline and cutout dimensions refer to Fig. 2.
The surface texture of the panel must be better
than 6,3 mmm.
The instrument is shipped with rubber panel
gasket (50 to 60 Sh).
To assure the IP65 and NEMA 4 protection, insert
the panel gasket between the instrument and the
panel as shown in fig. 1.
While holding the instrument against the panel
proceed as follows:
1) insert the gasket in the instrument case;
2) insert the instrument in the panel cutout;
3) pushing the instrument against the panel;
4) insert the mounting brackets as shown in fig.1;
5) with a screwdriver, turn the screws with a
torque between 0.3 and 0.4 Nm.
Xkc-1-C0.P65 5/29/02, 11:59 AM1
Screw
brackets
Screw
Gasket
1
Fig. 1
Panel
bracket
Screws
Gasket
bracket
Panel
Page 6
OUTLINE AND CUT OUT
DIMENSIONS
Fig. 2.A OUTLINE AND CUT-OUT DIMENSIONS FOR PKC MODEL
2
Xkc-1-C0.P65 5/29/02, 11:59 AM2
Page 7
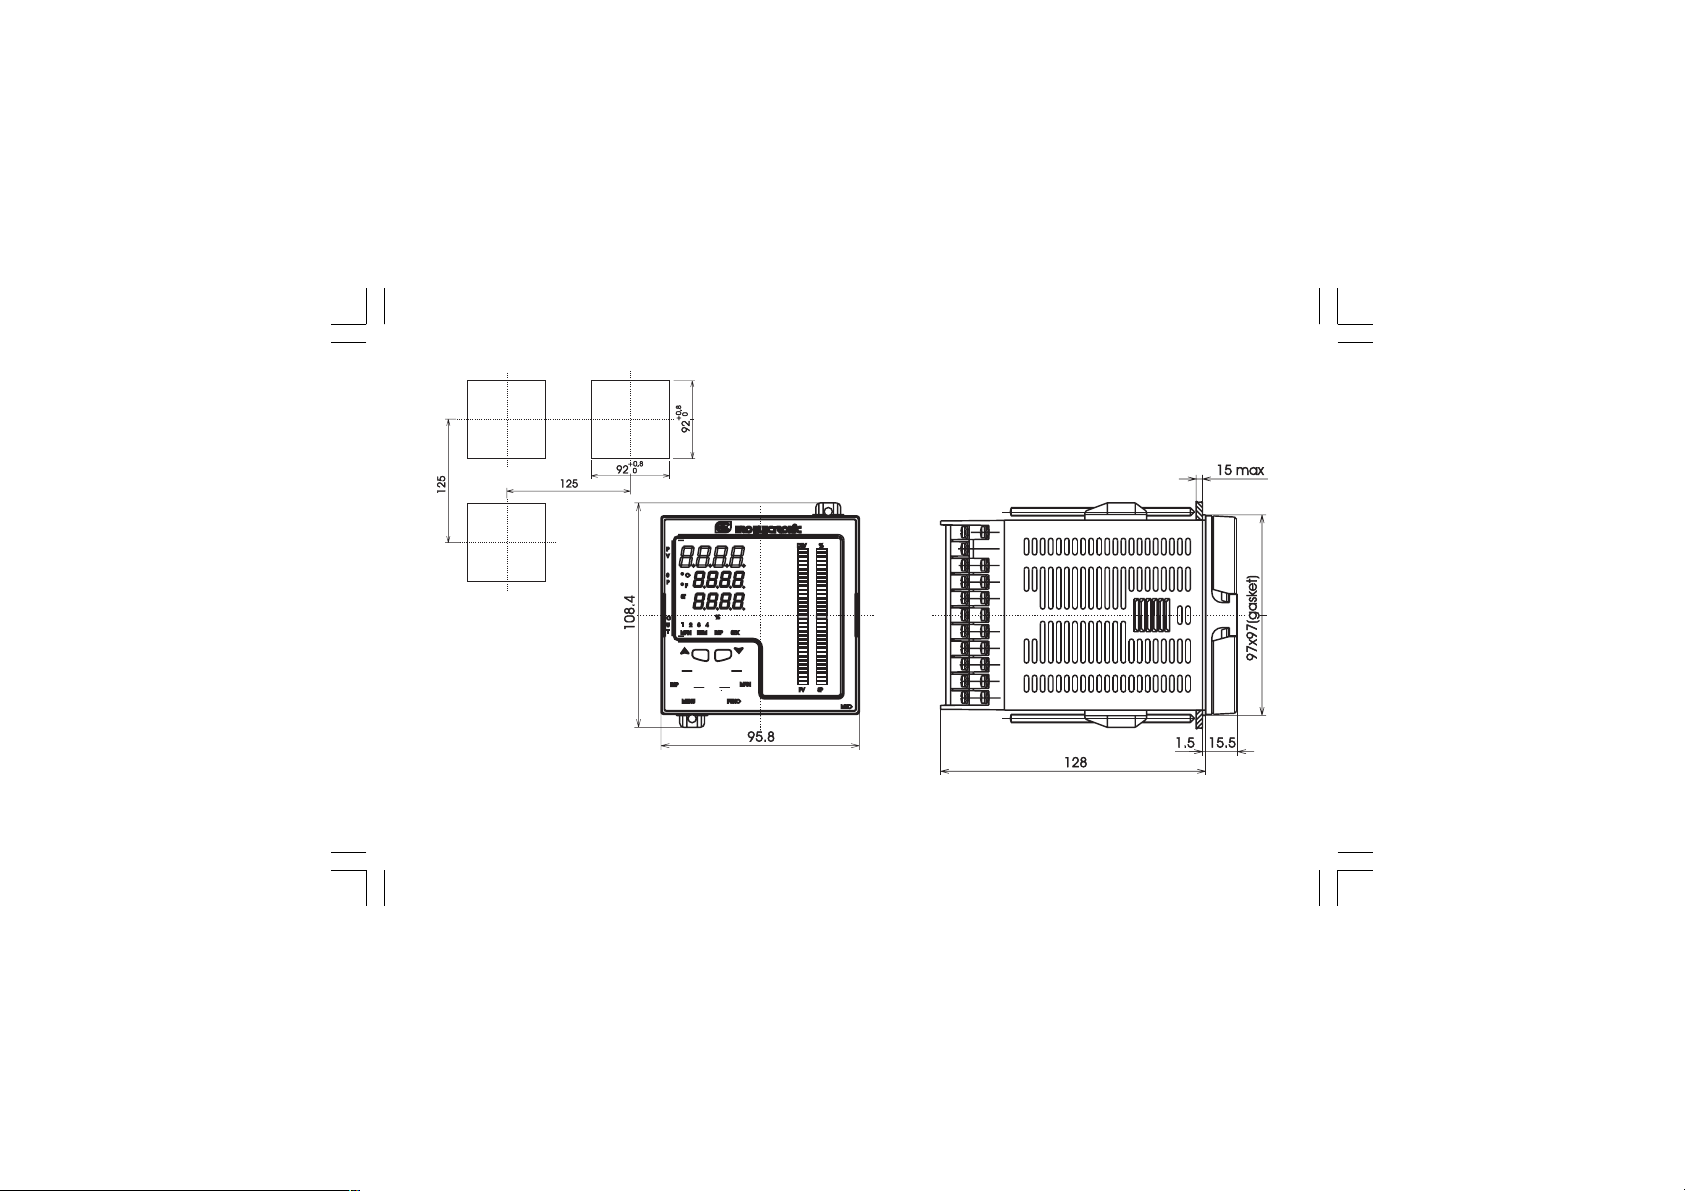
Fig. 2.B OUTLINE AND CUT-OUT DIMENSIONS FOR MKC MODEL
3
Xkc-1-C0.P65 5/29/02, 11:59 AM3
Page 8
CONNECTION DIAGRAMS
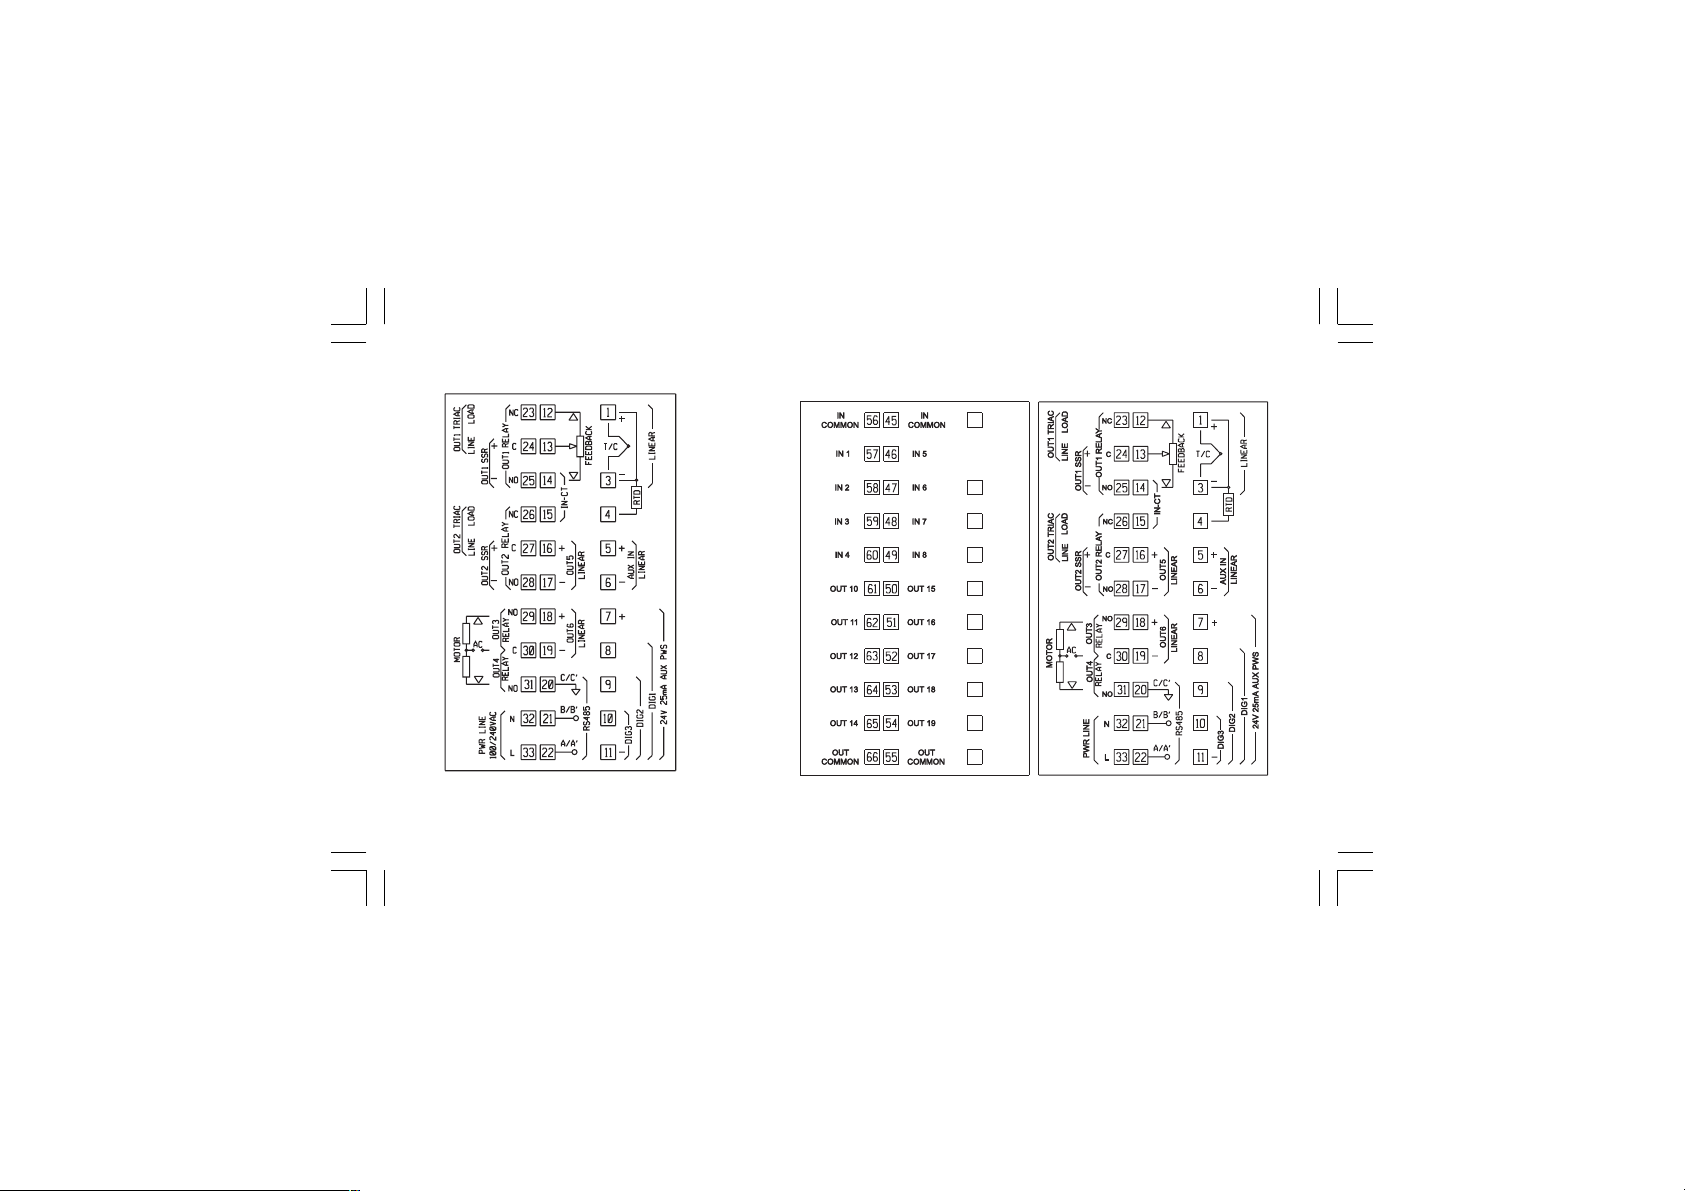
Fig. 3.A PKC -REAR TERMINAL BLOCK
Xkc-1-C0.P65 5/29/02, 11:59 AM4
Fig. 3.B MKC REAR TERMINAL BLOCK
4
Page 9
Connections are to be made with the instrument housing
installed in its proper location.
A) MEASURING INPUTS
NOTE: Any external component (like zener barriers etc.)
connected between sensor and input terminals may cause
errors in measurement due to excessive and/or not balanced
line resistance or possible leakage currents.
Xkc-1-C0.P65 5/29/02, 11:59 AM5
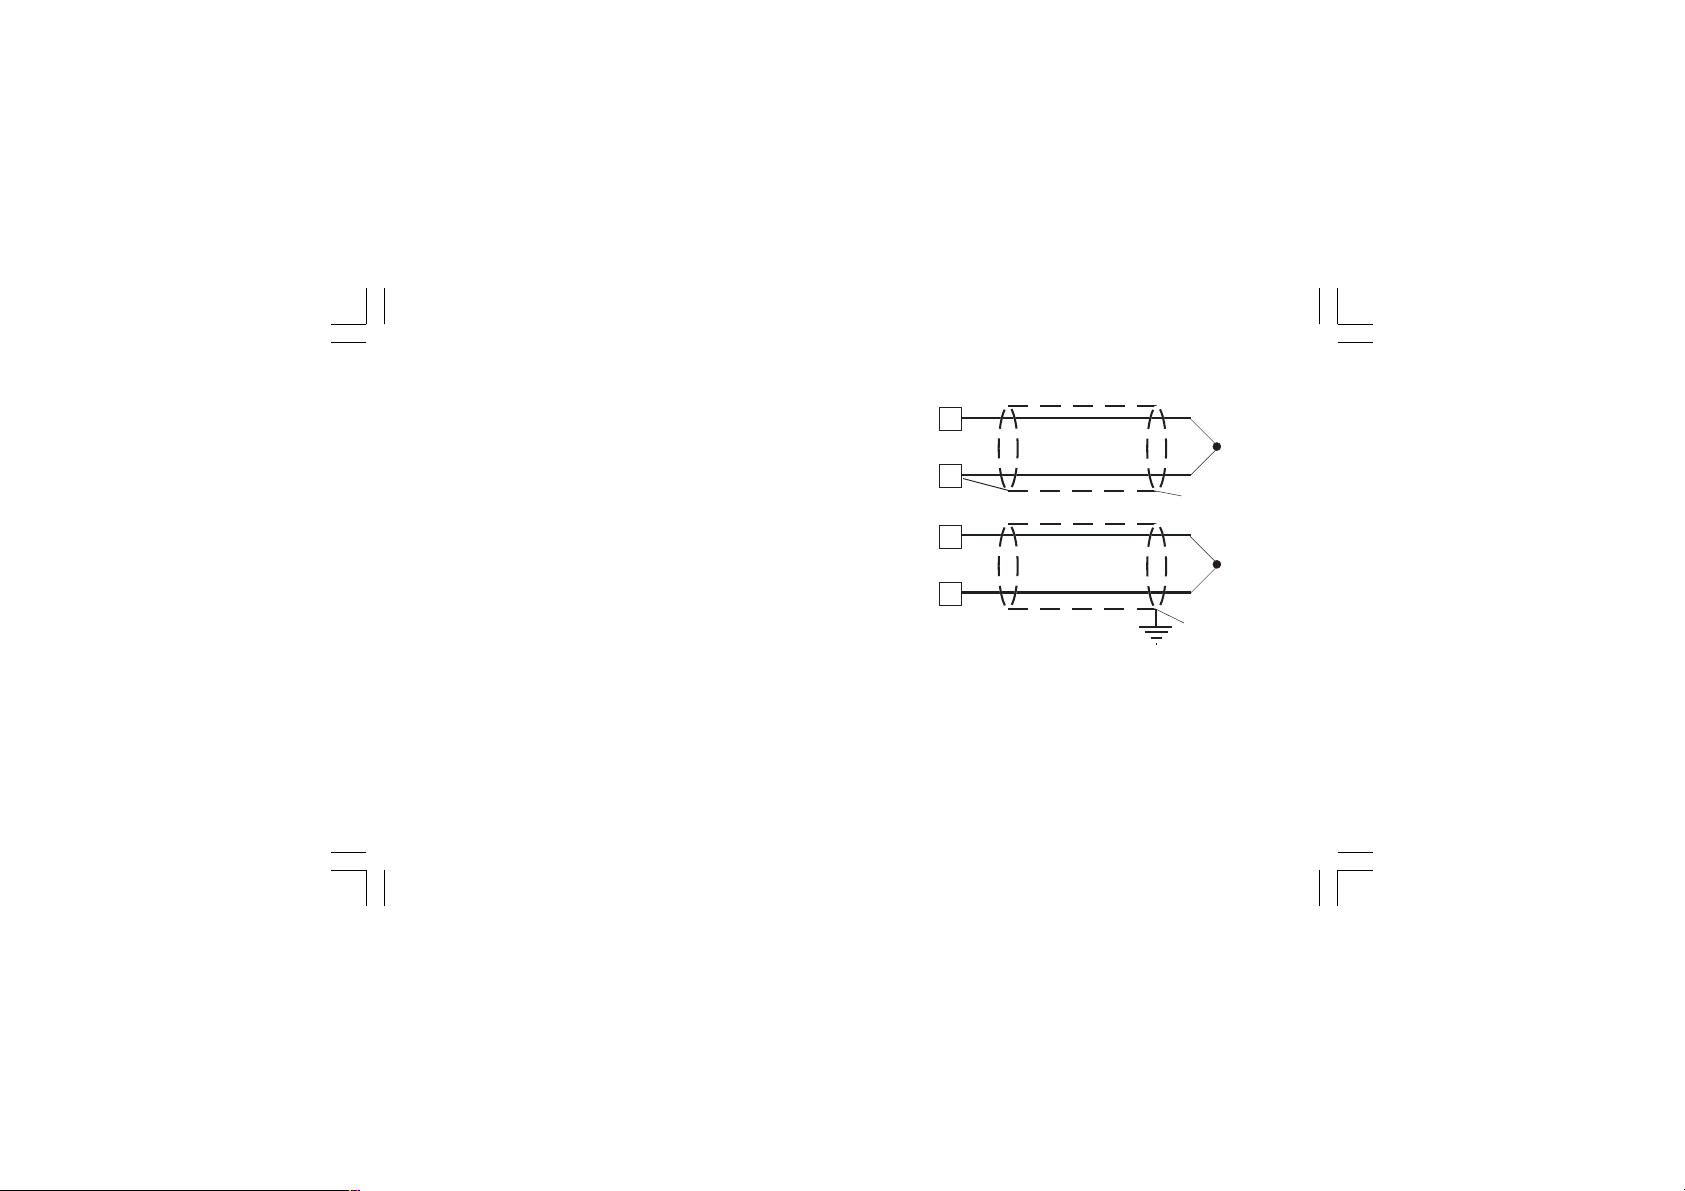
A.1) TC INPUT
1
+
_
3
1
+
_
3
Fig. 4 THERMOCOUPLE INPUT WIRING
NOTES:
1) Don’t run input wires together with power cables.
2) For TC wiring use proper compensating cable preferable
shielded.
3) When a shielded cable is used, it should be connected at
one point only.
5
Shield
Shield
Page 10
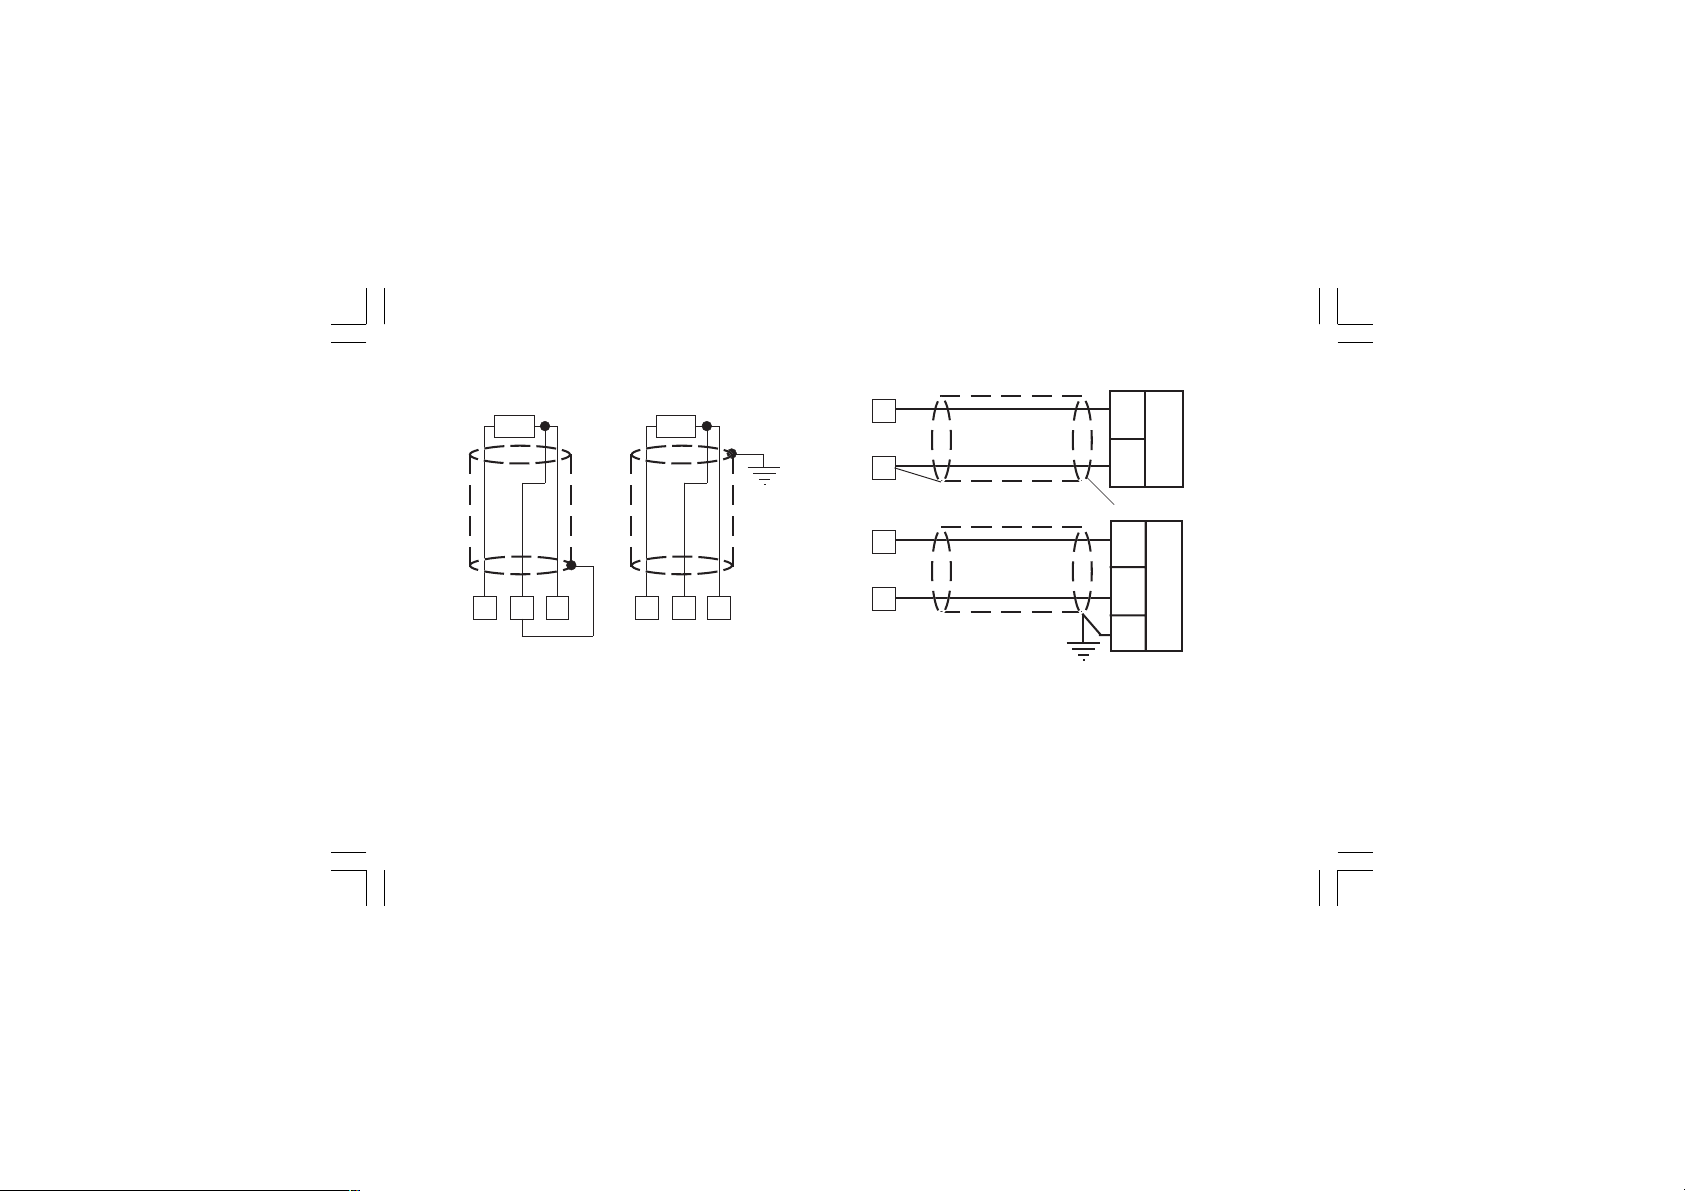
A.2) RTD INPUT
RTD
RTD
A.3) LINEAR INPUT
1
3
+
_
Shield
mA,
mV
or
V
4
Fig. 5 RTD INPUT WIRING
NOTES:
1) Don’t run input wires together with power cables.
2) Pay attention to the line resistance; a high line resistance may
cause measurement errors.
3) When shielded cable is used, it should be grounded at one
side only to avoid ground loop currents.
4) The resistance of the 3 wires must be the same.
Xkc-1-C0.P65 5/29/02, 11:59 AM6
13 4
13
1
3
+
mA
mV
_
or
V
G
Fig. 6 mA, mV AND V INPUTS WIRING
NOTES:
1) Don’t run input wires together with power cables.
2) Pay attention to the line resistance; a high line resistance may
cause measurement errors.
6
Page 11
3) When shielded cable is used, it should be grounded at one
side only to avoid ground loop currents.
4) The input impedance is equal to:
< 5 W for 20 mA input
> 1 MW for 60 mV input
> 200 kW for 5 V input
> 400 kW for 10 V input
1
Out
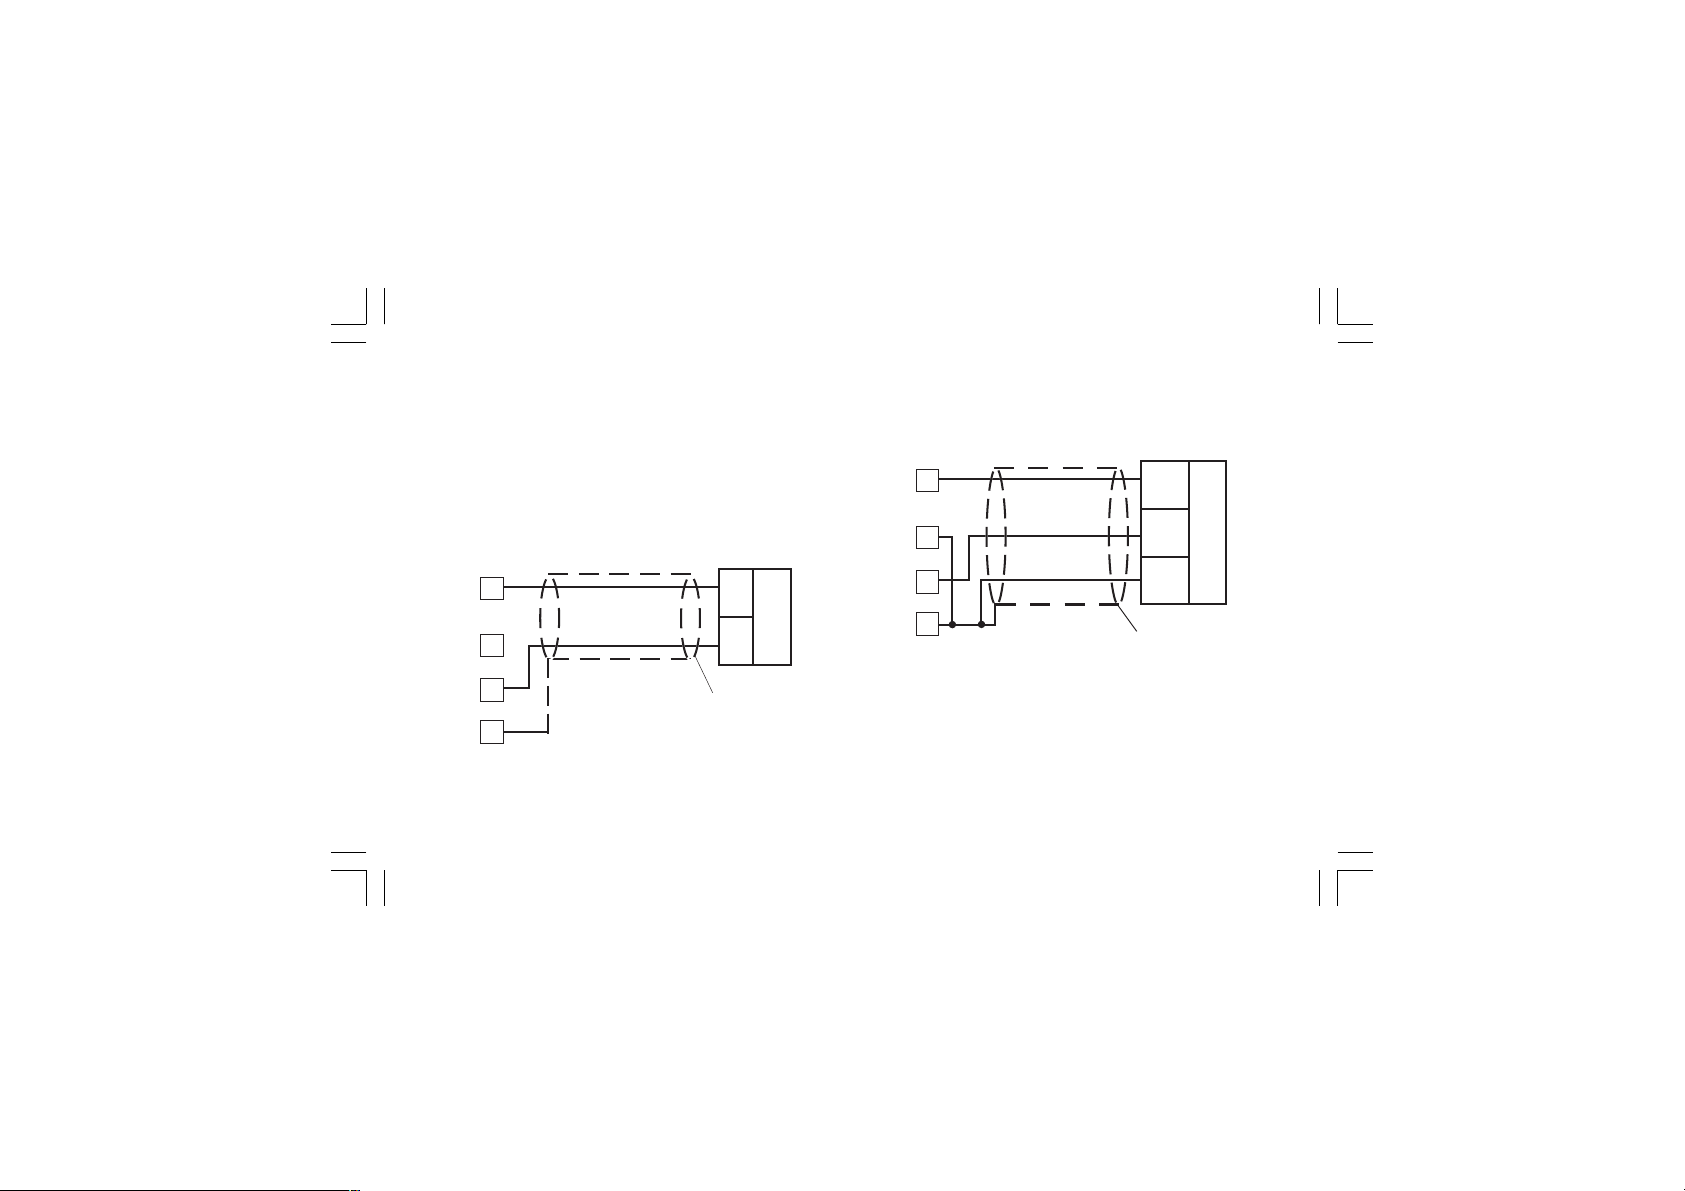
A.4) 2, 3 AND 4-WIRE TRANSMITTER INPUT
1
3
7
Shield
11
Fig. 7.A INPUTS WIRING FOR 2-WIRE TRANSMITTER
Xkc-1-C0.P65 5/29/02, 11:59 AM7
PWR
3
_
TX
+
7
7
11
Fig. 7.B INPUTS WIRING FOR 3-WIRE TRANSMITTER
Shield
+
GND
TX
Page 12
1
Out
+
Out
3
7
11
_
PWR
+
PWR
_
TX
Shield
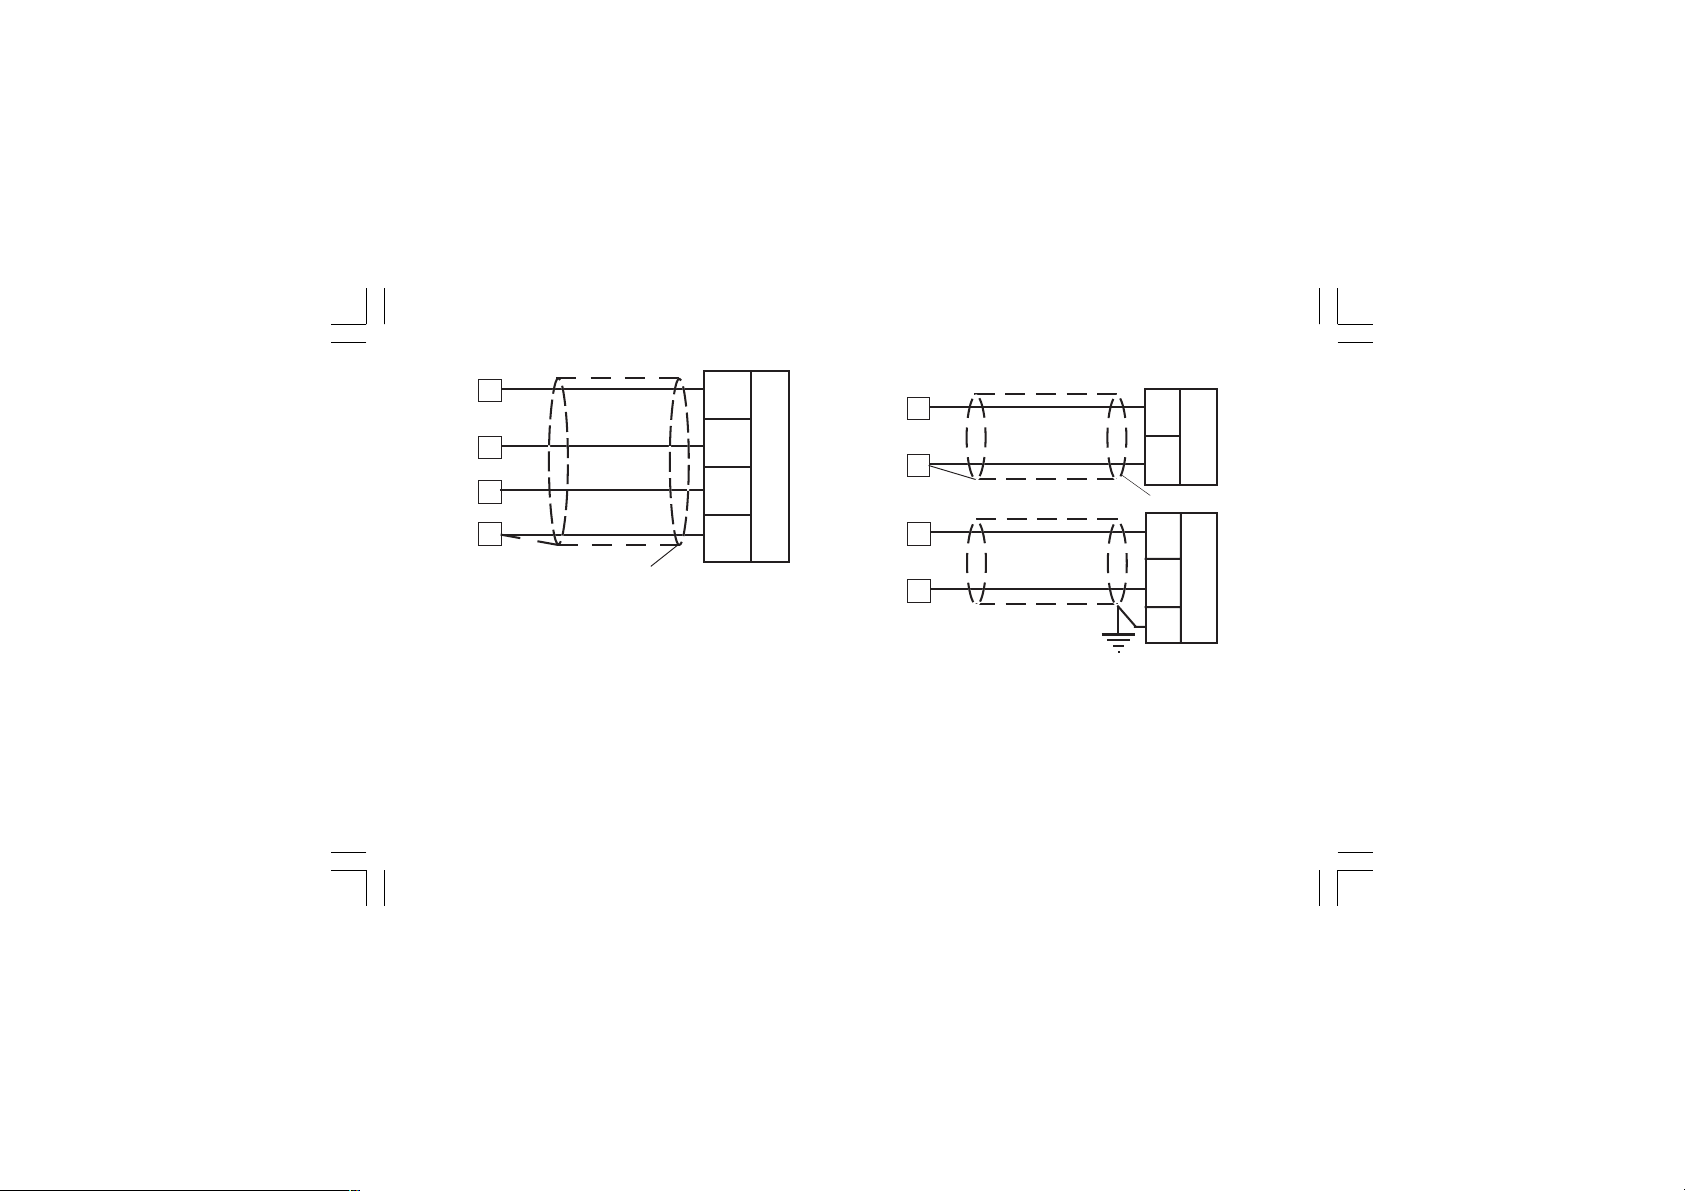
Fig. 7.C INPUTS WIRING FOR 4-WIRE TRANSMITTER
NOTES:
1) Don’t run input wires together with power cables.
2) Pay attention to the line resistance; a high line resistance may
cause measurement errors.
3) When shielded cable is used, it should be grounded at one
side only to avoid ground loop currents.
4) The input impedance is lower than 5 W (20 mA input)
Xkc-1-C0.P65 5/29/02, 11:59 AM8
B) AUXILIARY INPUT
5
6
+
mA
or
_
V
Shield
5
6
+
mA
_
or
V
G
Fig. 8 AUXILIARY INPUT WIRING
NOTES:
1) This input is not isolated from measuring input. A double or
reinforced insulation between instrument output and power
supply must be assured by the external instrument.
2) Don’t run input wires together with power cables.
3) Pay attention to the line resistance; a high line resistance may
cause measurement errors.
8
Page 13
4) When shielded cable is used, it should be grounded at one
side only to avoid ground loop currents.
5) The input impedance is equal to:
< 5 W for 20 mA input
> 200 kW for 5 V input
> 400 kW for 10 V input
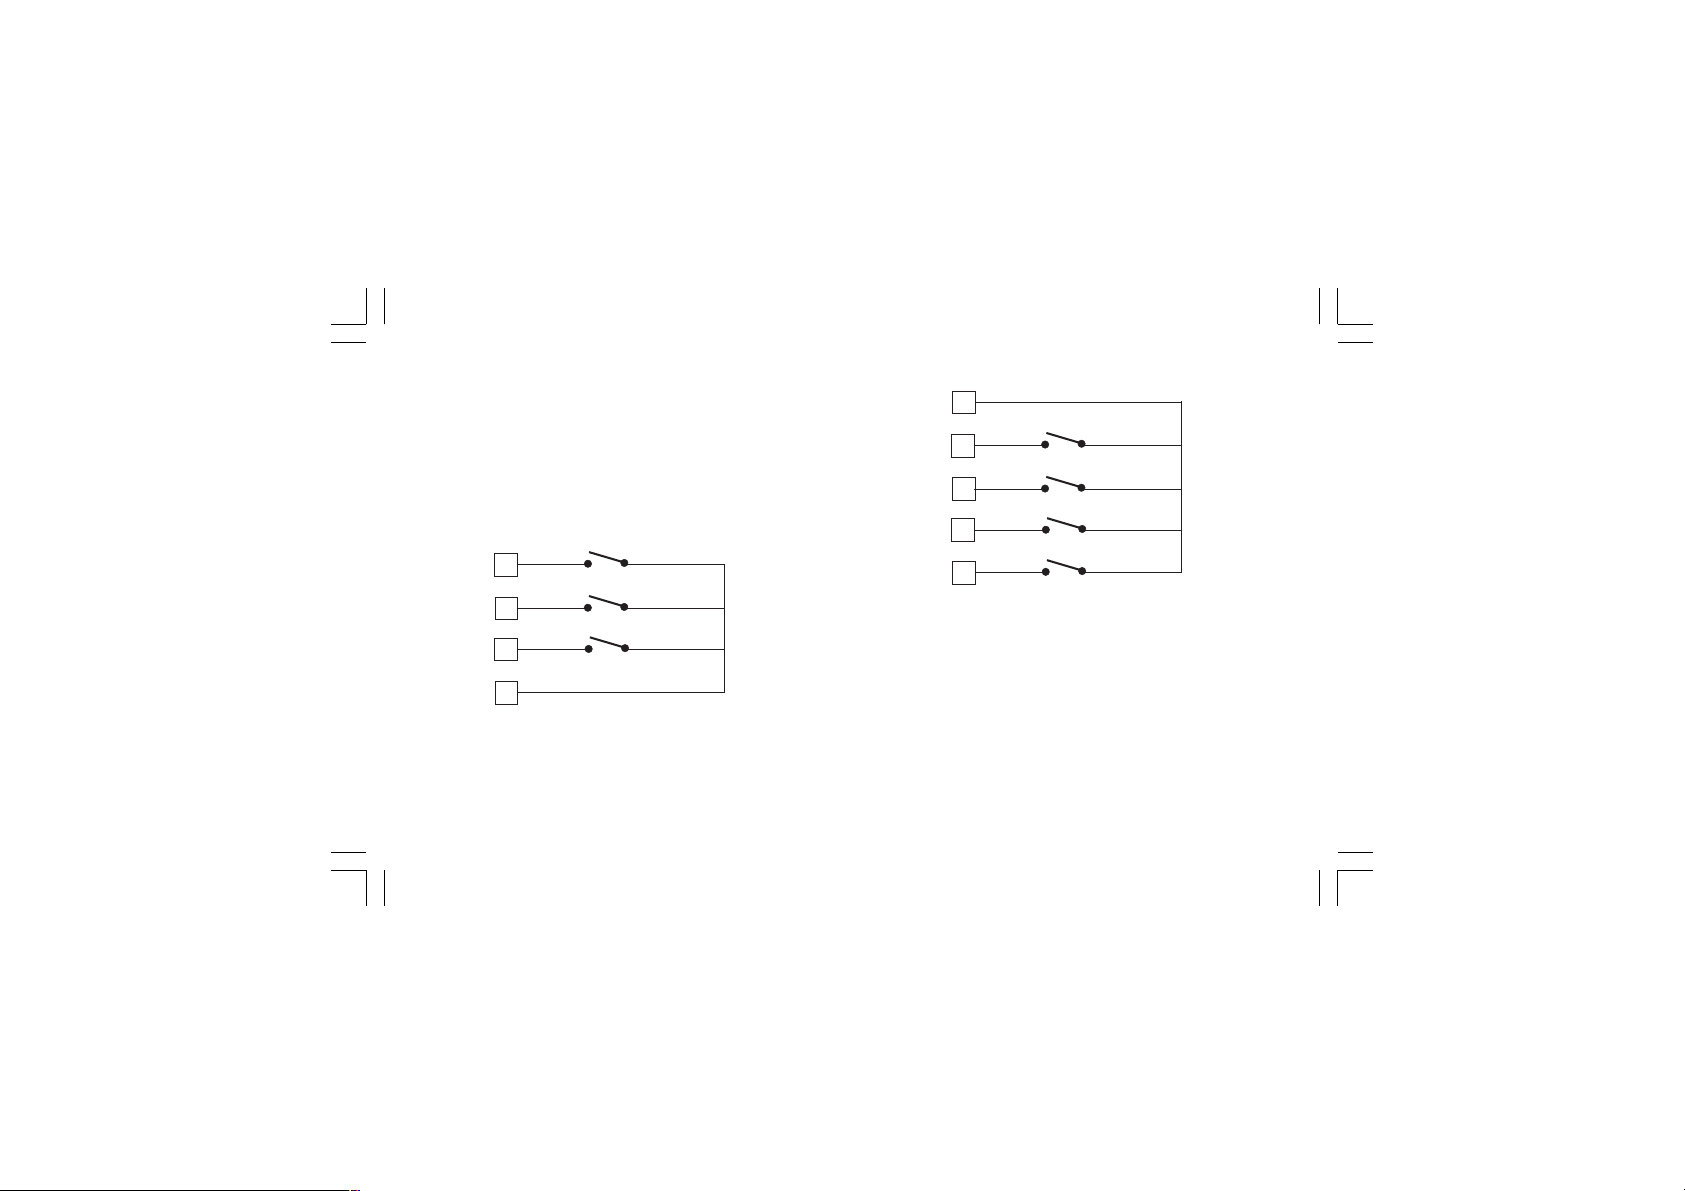
C) LOGIC INPUT
DIG. 1
8
DIG. 2
9
DIG. 3
10
11
Fig. 9.A - LOGIC INPUTS DIG.1, 2 and 3 WIRING
Xkc-1-C0.P65 5/29/02, 11:59 AM9
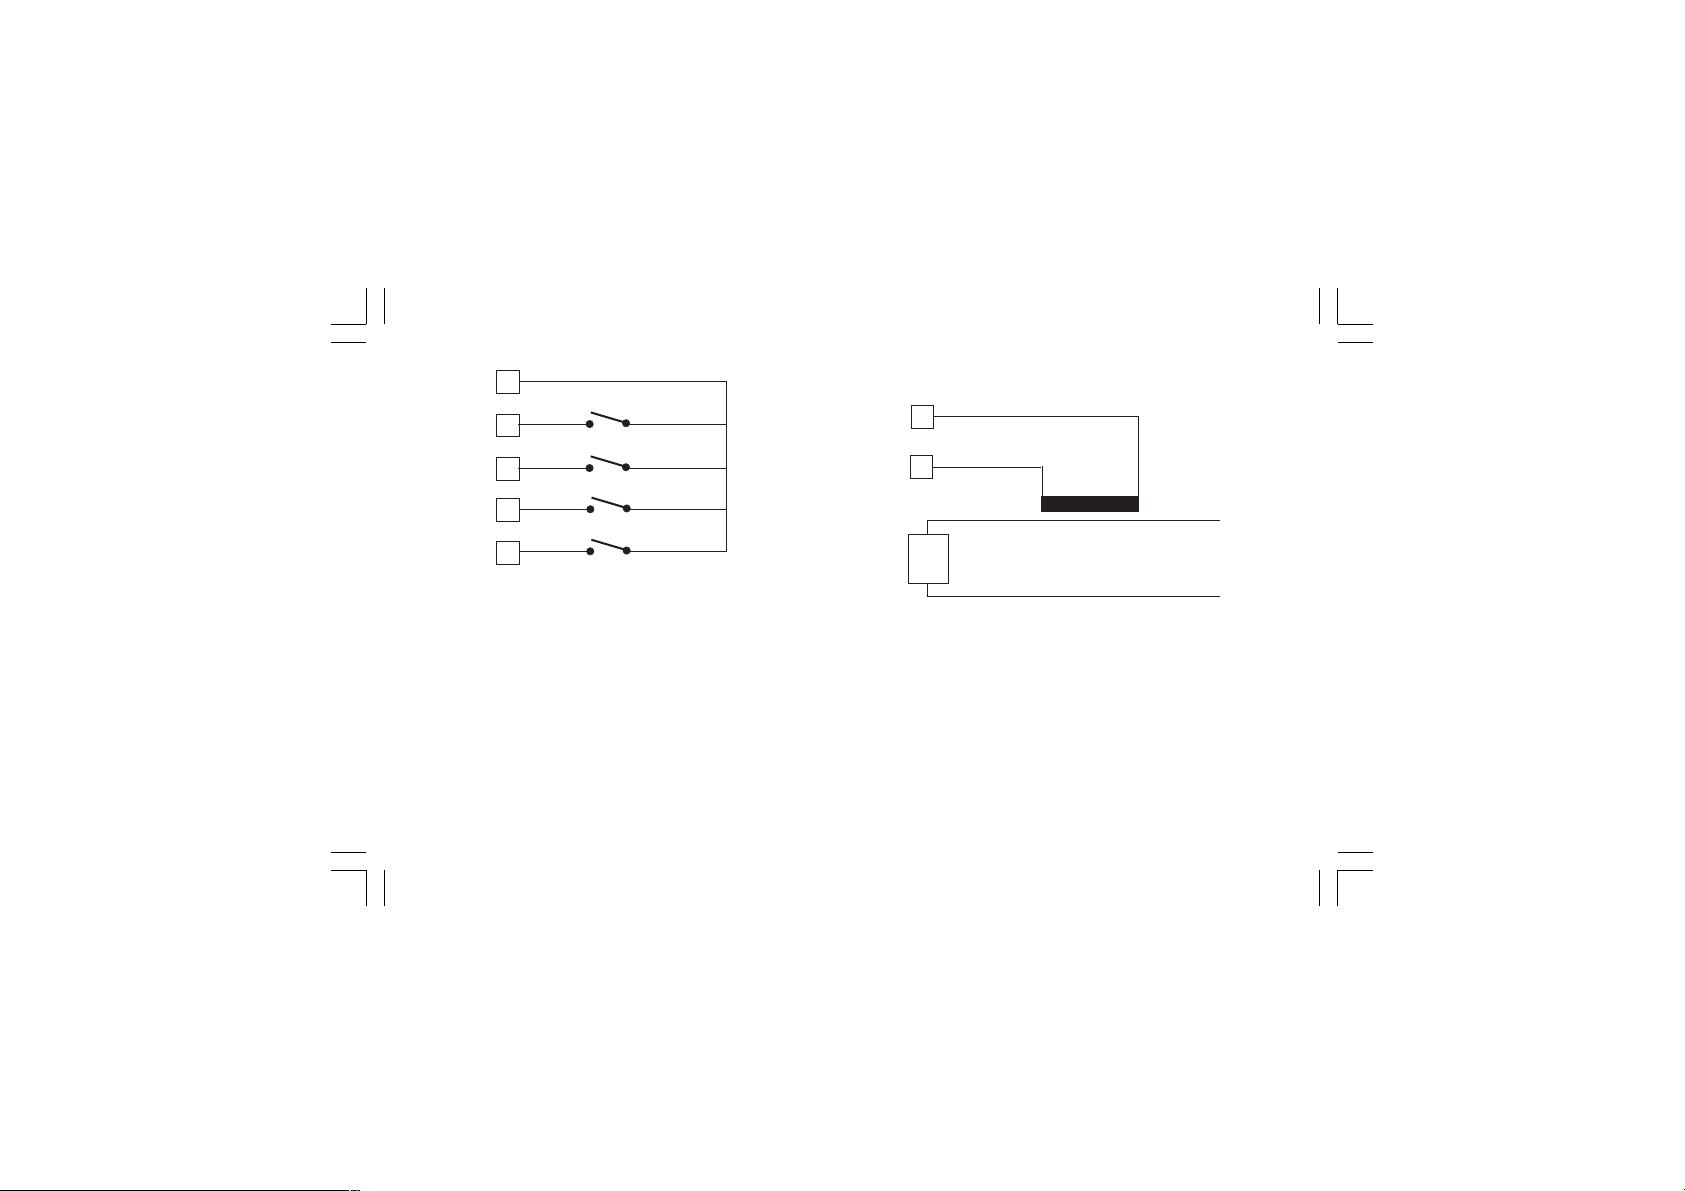
56
IN 1
57
IN 2
58
IN 3
59
IN 4
60
Fig. 9.B - LOGIC INPUTS IN 1, 2, 3 and 4 WIRING
9
Page 14
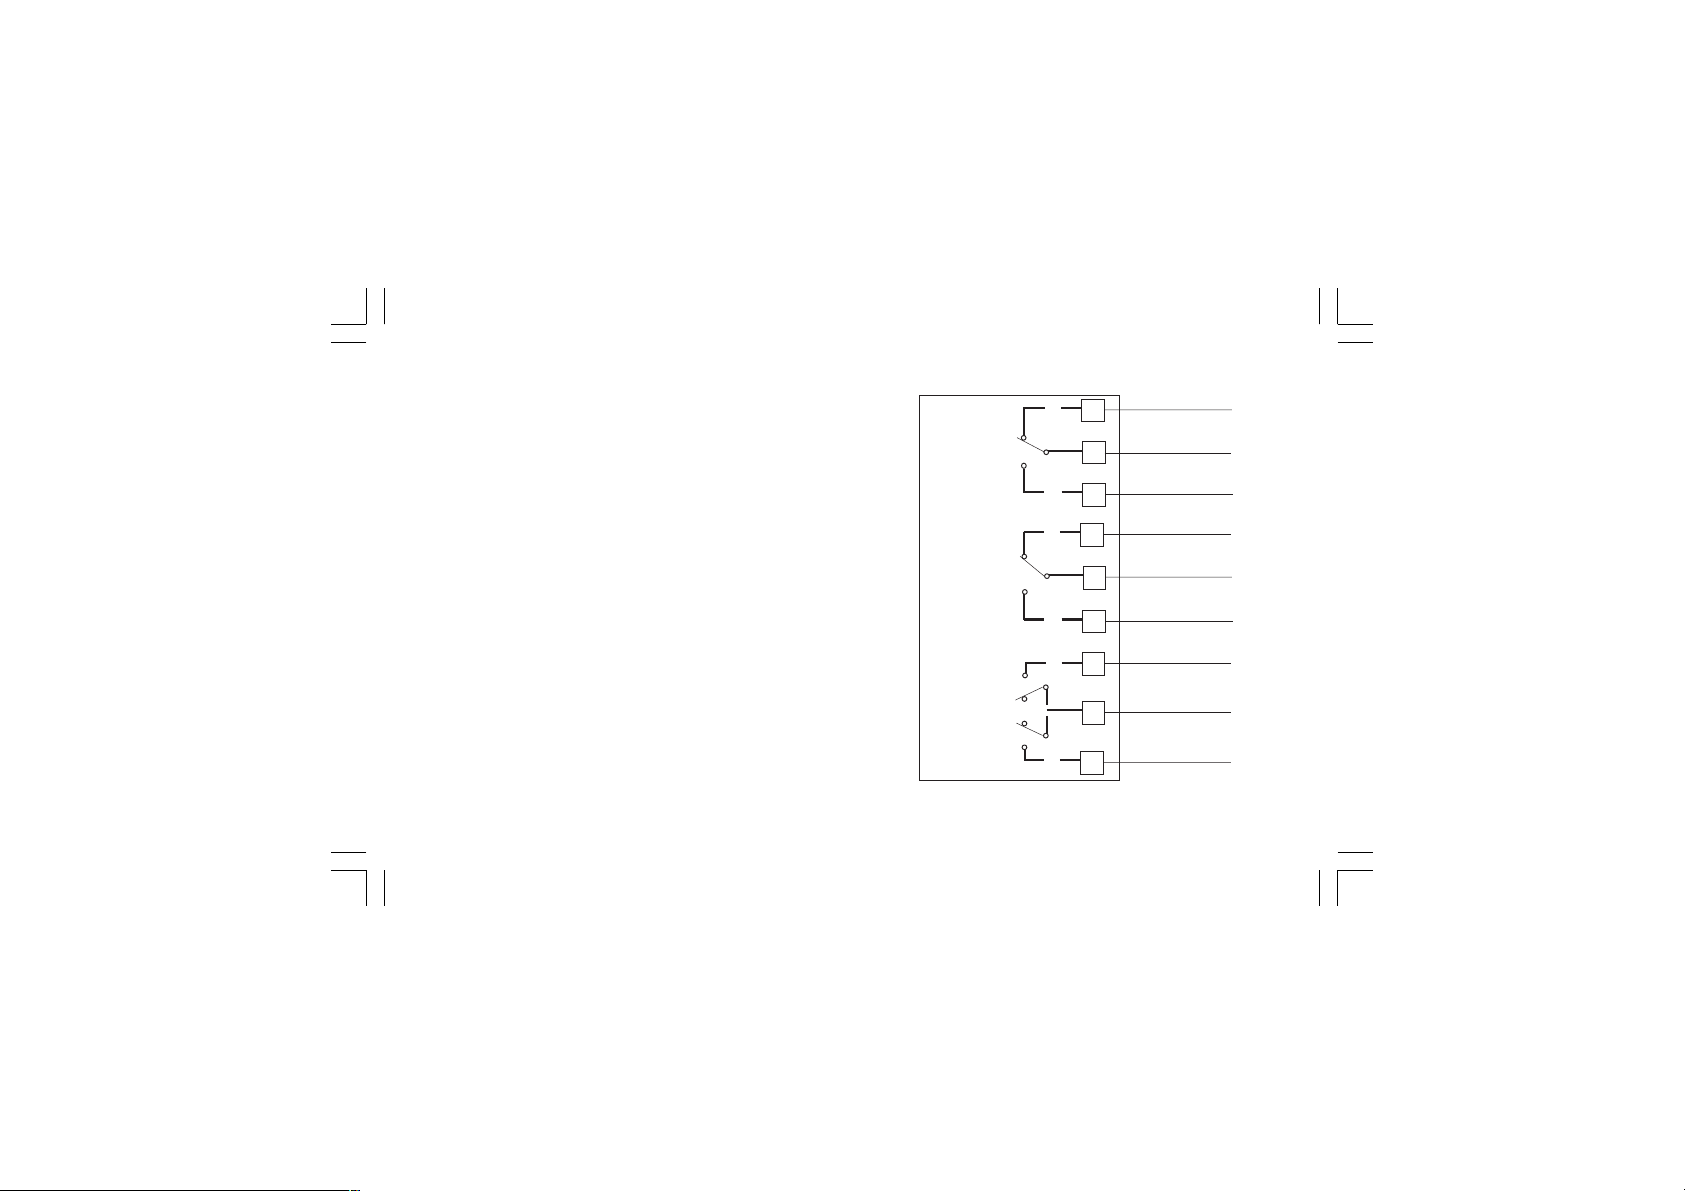
45
IN 5
46
IN 6
47
IN 7
48
IN 8
49
Fig. 9.c - LOGIC INPUTS IN 5, 6, 7 and 8 WIRING
NOTES:
1) Do not run logic input wiring together with power cables.
2) Use an external dry contact capable of switching 0.5 mA,
5 V DC.
3) The instrument needs 110 ms to recognize a contact status
variation.
4) The logic inputs are NOT isolated by the measuring input. A
double or reinforced insulation between instrument output and
power supply must be assured by the external element.
Xkc-1-C0.P65 5/29/02, 11:59 AM10
D) CURRENT TRANSFORMER INPUT
14
Current
15
Load
Fig. 10 CURRENT TRANSFORMER INPUT WIRING
This input allows you to measure and display the current running
in the load, driven by a time proportional control output, during
the ON and OFF periods of the output cycle time. By this feature
it is also available the "Output failure detection" function (see
page 66).
10
transformer
Page 15
NOTES:
1) This input is not isolated from measuring input. A double or
reinforced insulation between instrument output and power
supply must be assured by the external element.
2) Do not run current transformer input wiring together with AC
power cables.
3) The minimum active period to perform this measurement is
equal to 120 ms.
4) The input impedance is equal to 20 W.
Xkc-1-C0.P65 5/29/02, 11:59 AM11
E.1) RELAY OUTPUTS
23
OUT 1
24
25
26
OUT 2
27
28
29
OUT 3
30
OUT 4
31
Fig. 11.A RELAY OUTPUTS 1,2,3 and 4 WIRING
11
NC
C
NO
NC
C
NO
NO - OUT 3
C - OUT 3/4
NO - OUT 4
Page 16
The outputs from OUT 1 to OUT 4 are equipped with relays
having contact rating equal to 3A/250V AC on resistive load.
WARNING: When OUT 3 and 4 are used as independent relay
outputs the addition of the two currents must not exceed 3 A.
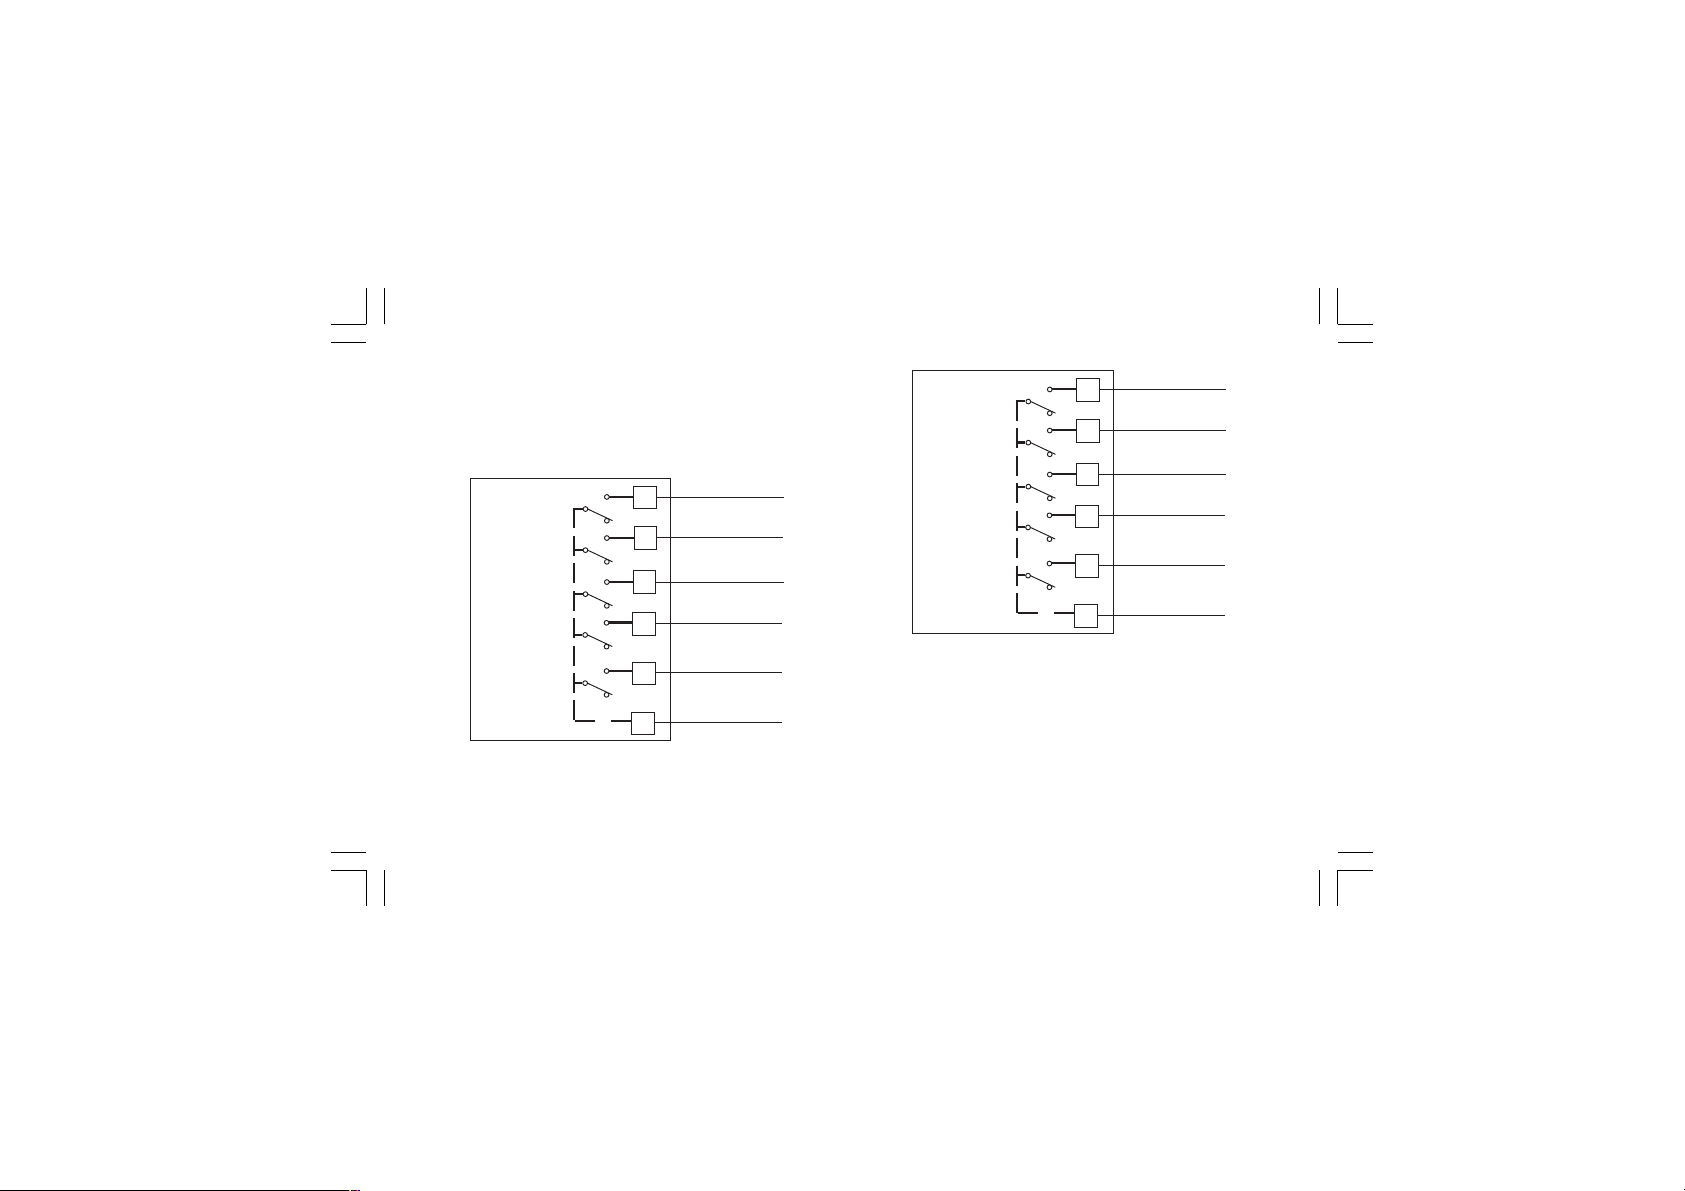
NO OUT 10
OUT 10
OUT 11
OUT 12
OUT 13
OUT 14
COMMON
Fig. 11.B RELAY OUTPUTS 10 to 14 WIRING
Xkc-1-C0.P65 5/29/02, 11:59 AM12
61
62
63
64
65
66
NO OUT 11
NO OUT 12
NO OUT 13
NO OUT 14
COMMON
NO OUT 15
OUT 15
OUT 16
OUT 17
OUT 18
OUT 19
COMMON
Fig. 11.C RELAY OUTPUTS 15 to 19 WIRING
The outputs from OUT 10 to 19 are equipped with relays having
contact rating equal to 0.5A/250V AC on resistive load.
12
50
51
52
53
54
55
NO OUT 16
NO OUT 17
NO OUT 18
NO OUT 19
COMMON
Page 17
NOTES 1) To avoid electrical shock, connect power line at
the end of the wiring procedure.
2) For power connections use No 16 AWG or larger
wires rated for at last 75 °C.
3) Use copper conductors only.
4) Don’t run input wires together with power cables.
All relay contacts are protected by varistor against inductive load
with inductive component up to 0.5 A.
The following recommendations avoid serious problems which
may occur, when using relay output for driving inductive loads.
INDUCTIVE LOADS
High voltage transients may occur switching inductive loads.
Through the internal contacts these transients may introduce
disturbances which can affect the performance of the instrument.
For all the outputs, the internal protection (varistor) assures a
correct protection up to 0.5 A of inductive component.
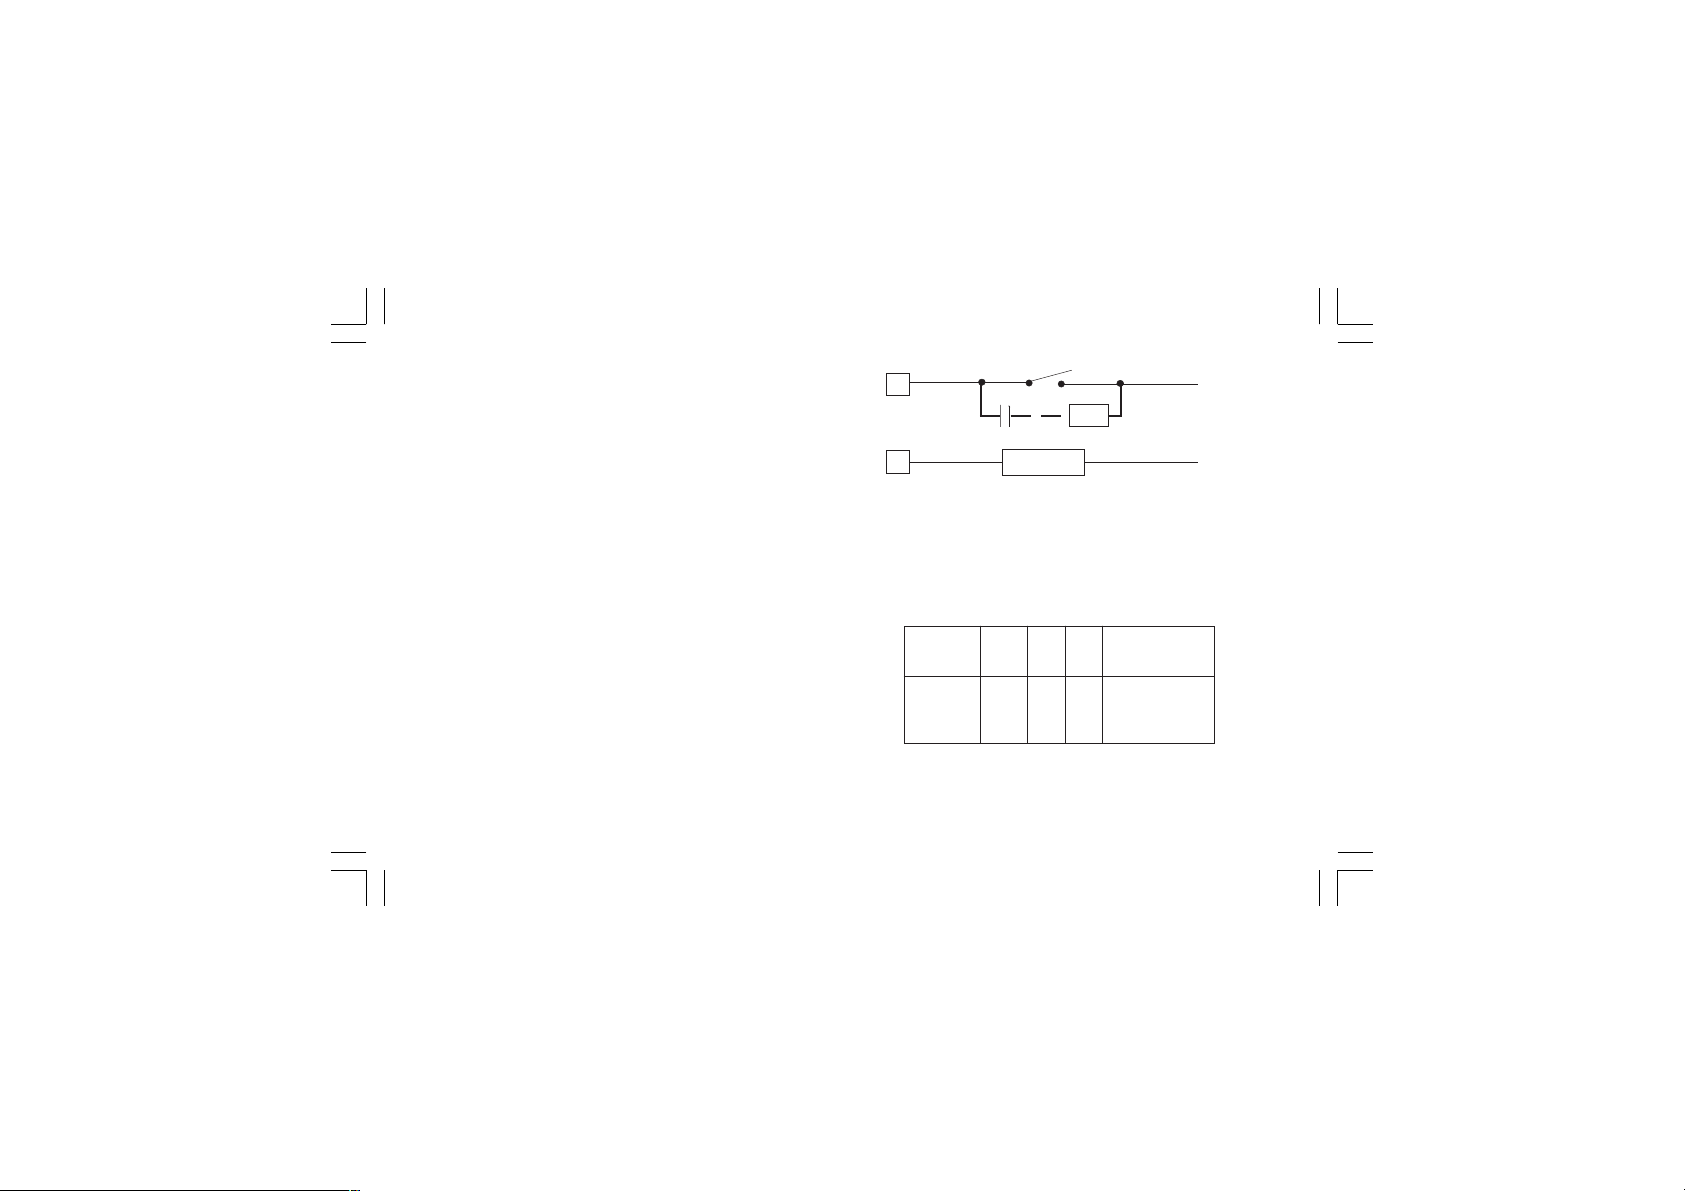
The same problem may occur when a switch is used in series
with the internal contacts as shown in Fig. 12.
Xkc-1-C0.P65 5/29/02, 11:59 AM13
C
R
LINE
LOAD
Fig. 12 EXTERNAL SWITCH IN SERIES WITH THE INTER-
NAL CONTACT
In this case it is recommended to install an additional RC
network across the external contact as show in Fig. 12
The value of capacitor (C) and resistor (R) are shown in the
following table.
LOAD
(mA)
<40 mA
<150 mA
<0.5 A
Anyway the cable involved in relay output wiring must be as far
away as possible from input or communication cables.
13
C
(mF)
0.047
0.1
0.33
R
(W)
100
22
47
P.
(W)
1/2
2
2
OPERATING
VOLTAGE
260 V AC
260 V AC
260 V AC
Page 18
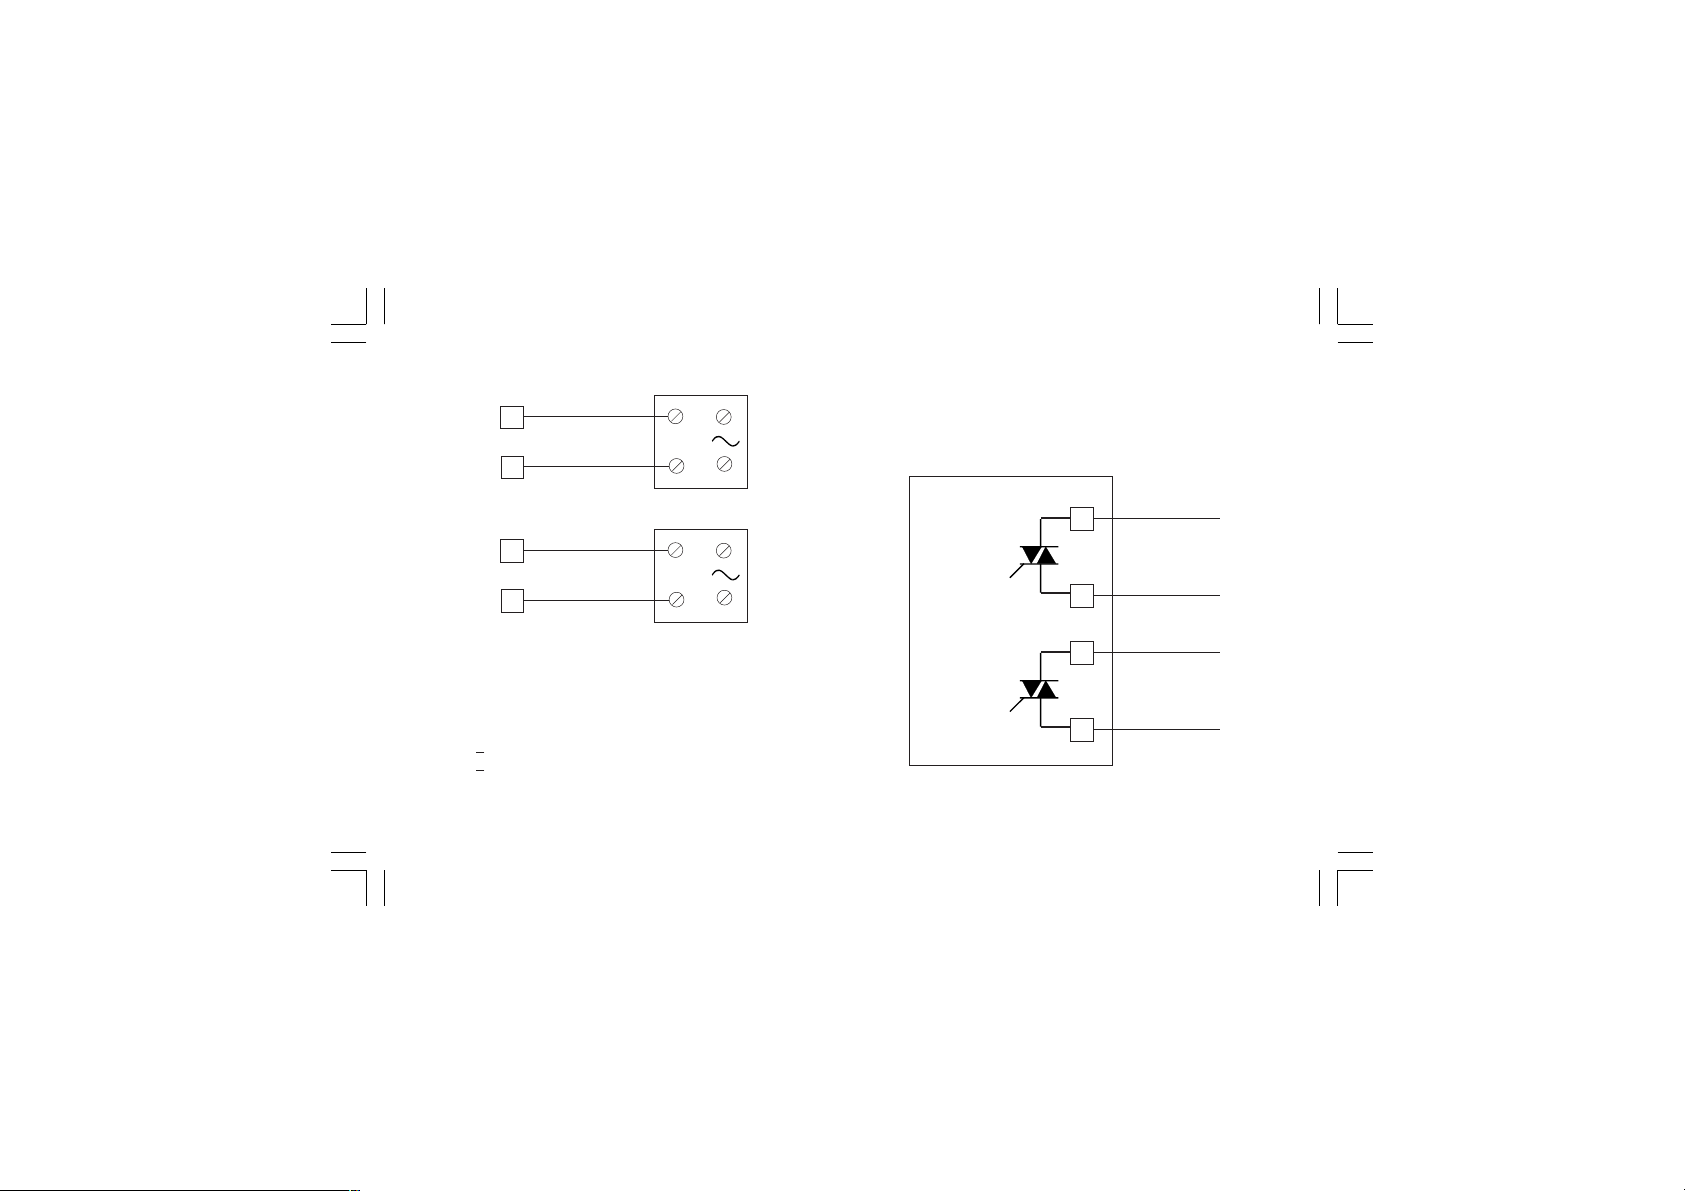
E.2) VOLTAGE OUTPUTS FOR SSR DRIVE
24
OUT 1
+
_
25
SOLID STATE
27
OUT 2
+
_
28
SOLID STATE
Fig. 13 SSR DRIVE OUTPUT WIRING
Logic level 0: Vout < 0.5 V DC.
Logic level 1:
+ 20 % @ 20 mA
- 14 V
- 24 V
+ 20 % @ 1 mA.
Maximum current = 20 mA.
Xkc-1-C0.P65 5/29/02, 11:59 AM14
+
_
RELAY
+
_
RELAY
NOTE: This output is not isolated.
A double or reinforced insulation between instrument output and
power supply must be assured by the external solid state relay.
E.3) TRIAC OUTPUTS
24
Line
OUT 1
23
27
Load
Line
OUT 2
26
Fig. 14 TRIAC OUTPUT WIRING
14
Load
Page 19
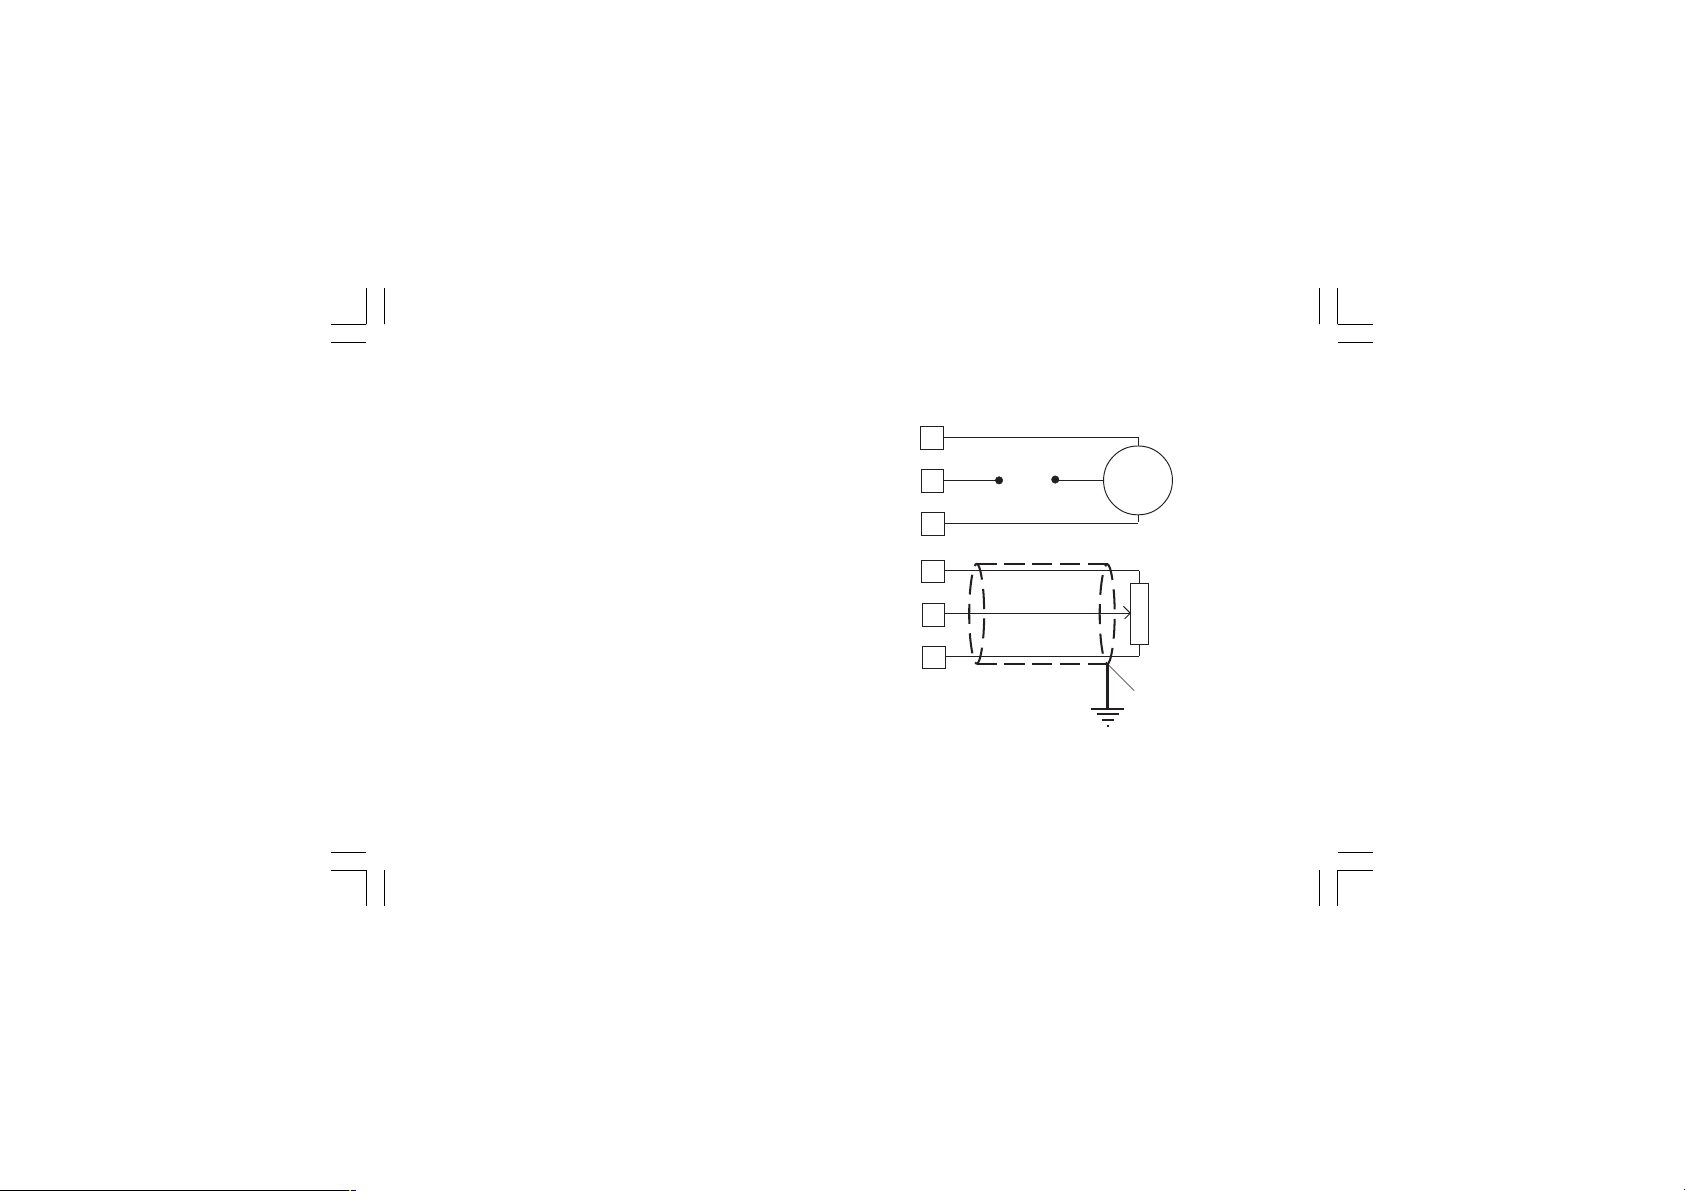
Switching mode: isolated zero crossing type.
Rated current: from 50 mA to 1 A.
Rated voltage: from 24 V
60Hz)
to 240 V
RMS
-10 % +15 % (50/
RMS
Load type: resistive load only
NOTES 1) To avoid electrical shock, connect power line at
the end of the wiring procedure.
2) For power connections use No 16 AWG or larger
wires rated for at last 75 °C.
3) Use copper conductors only.
4) Don’t run input wires together with power cables.
5) This output is not fuse protected. Please, provide it
externally using a fuse with a I2t equal to128.
Xkc-1-C0.P65 5/29/02, 11:59 AM15
E.4) SERVOMOTOR OUTPUT
s (Open the valve)
29
30
31
Power
line
t (Close the valve)
12
13
14
Fig. 15 SERVOMOTOR OUTPUT WIRING
15
Servo-
motor
s (Open)
t (Close)
Shield
Feedback
potentiometer
Page 20
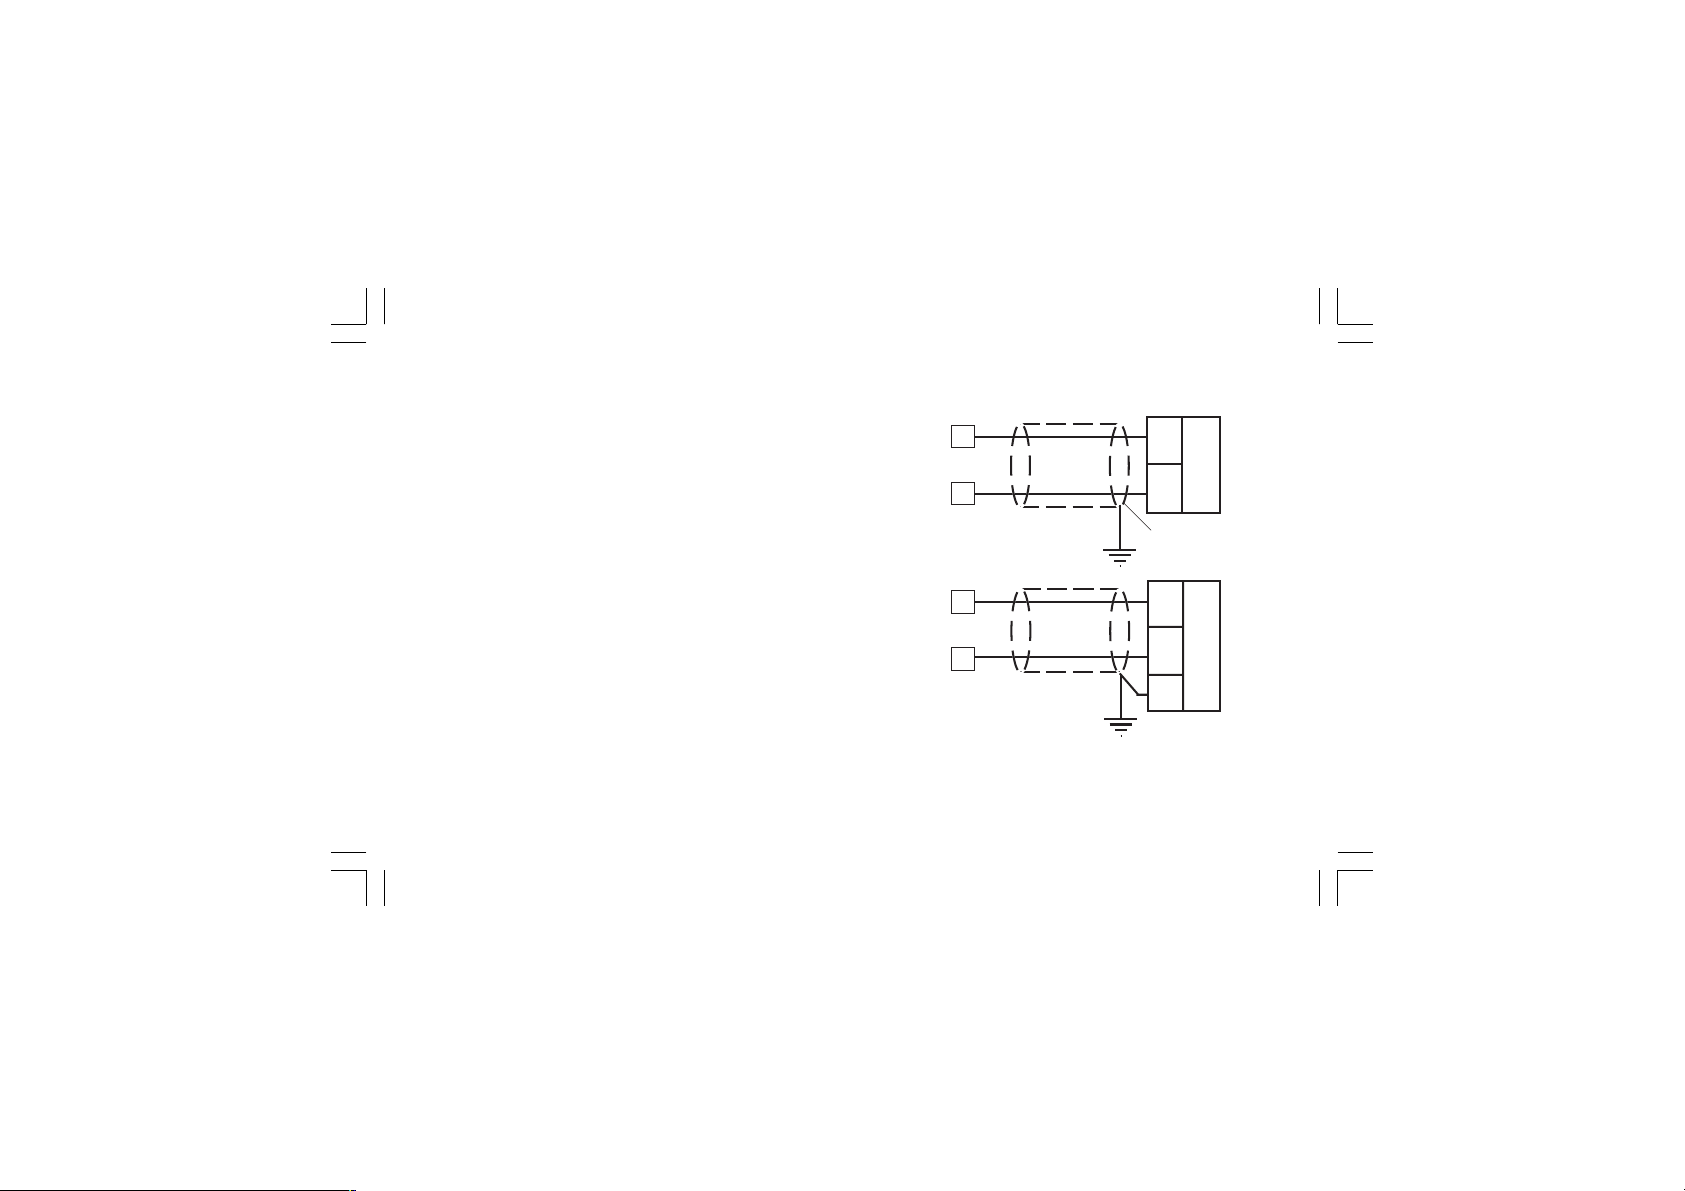
The two relay output must be interlocked (see chapter
"Preliminary hardware setting" paragraph "Out 3 and 4
selection").
NOTES:
1) Before connecting the instrument to the power line, make sure
that line voltage and the load current are in accordance with the
contact rating (3A/250V AC on resistive load).
2) To avoid electric shock, connect power line at the end of the
wiring procedure.
3) For servomotor connections use No 16 AWG or larger wires
rated for at last 75 °C.
4) Use copper conductors only.
5) Don’t run input wires together with power cables.
6) For feedback potentiometer, use shielded cable with the shield
connected to the earth at one point only.
7) The relay outputs are protected by varistor against inductive
load with inductive component up to 0.5 A.
Xkc-1-C0.P65 5/29/02, 11:59 AM16
E.5) ANALOG OUTPUTS
+
16
OUT 5
_
17
+
16
OUT 5
_
17
Fig. 16.A OUTPUT 5 WIRING
16
+
_
Shield
+
_
G
20 mA20 mA
Page 21
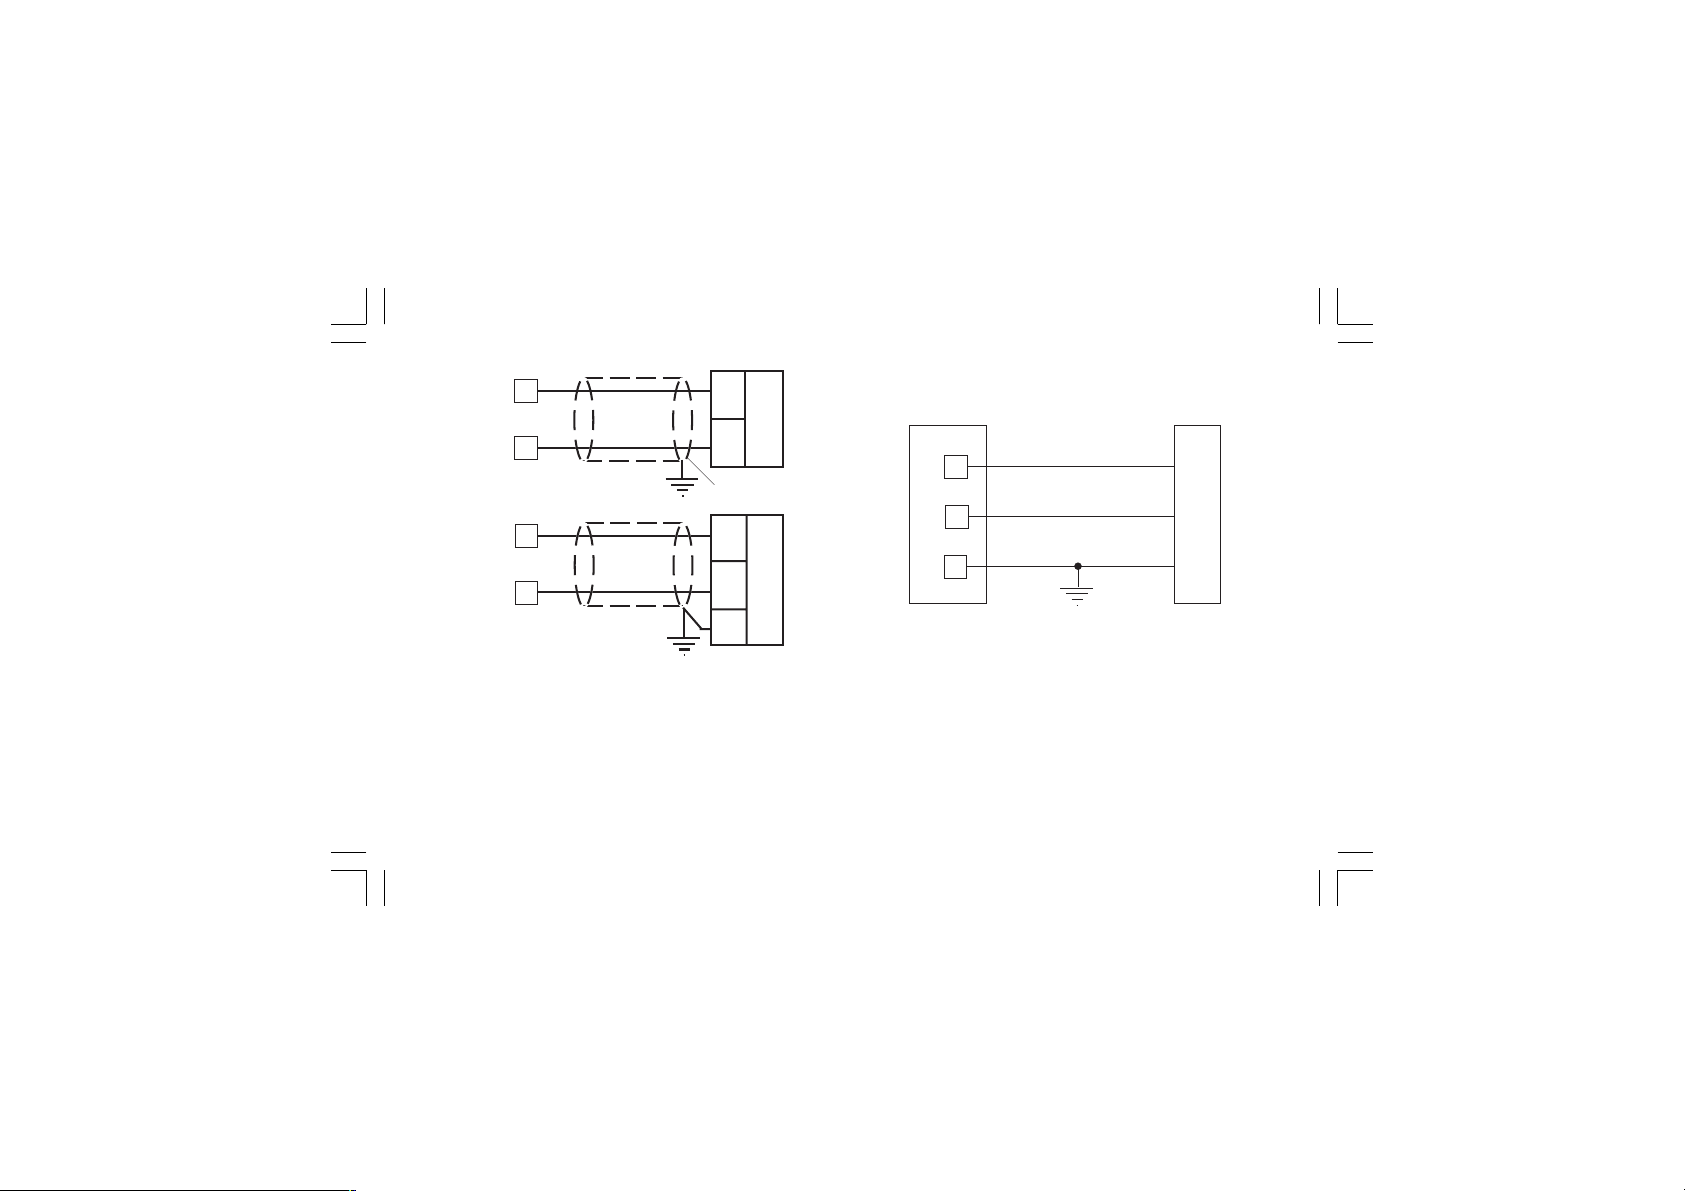
+
OUT 6
18
_
19
+
_
Shield
OUT 6
18
19
+
_
+
_
G
Fig. 16.B OUTPUT 6 WIRING
NOTE:
1) Do not run analog output wirings together with AC power
cables.
2) Out 5 and 6 are isolated outputs.
3) The maximum load is equal to 600 W.
Xkc-1-C0.P65 5/29/02, 11:59 AM17
20 mA
20 mA
F) SERIAL INTERFACE
RS-485 interface allows you to connect up to 30 devices with
one remote master unit.
I
N
S
T
R
U
M
E
N
T
Fig. 17 - RS-485 WIRING
NOTES:
1) The cable length must not exceed 1.5 km at 9600 BAUD.
2) This serial interface is isolated.
3) The following report describes the signal sense of the voltage
appearing across the interconnection cable as defined by
EIA for RS-485.
a) The ” A ” terminal of the generator shall be negative with
respect to the ” B ” terminal for a binary 1 (MARK or OFF) state.
17
22
21
20
A/A'
B/B'
COMMON
A'/A
B'/B
M
A
S
T
E
R
Page 22
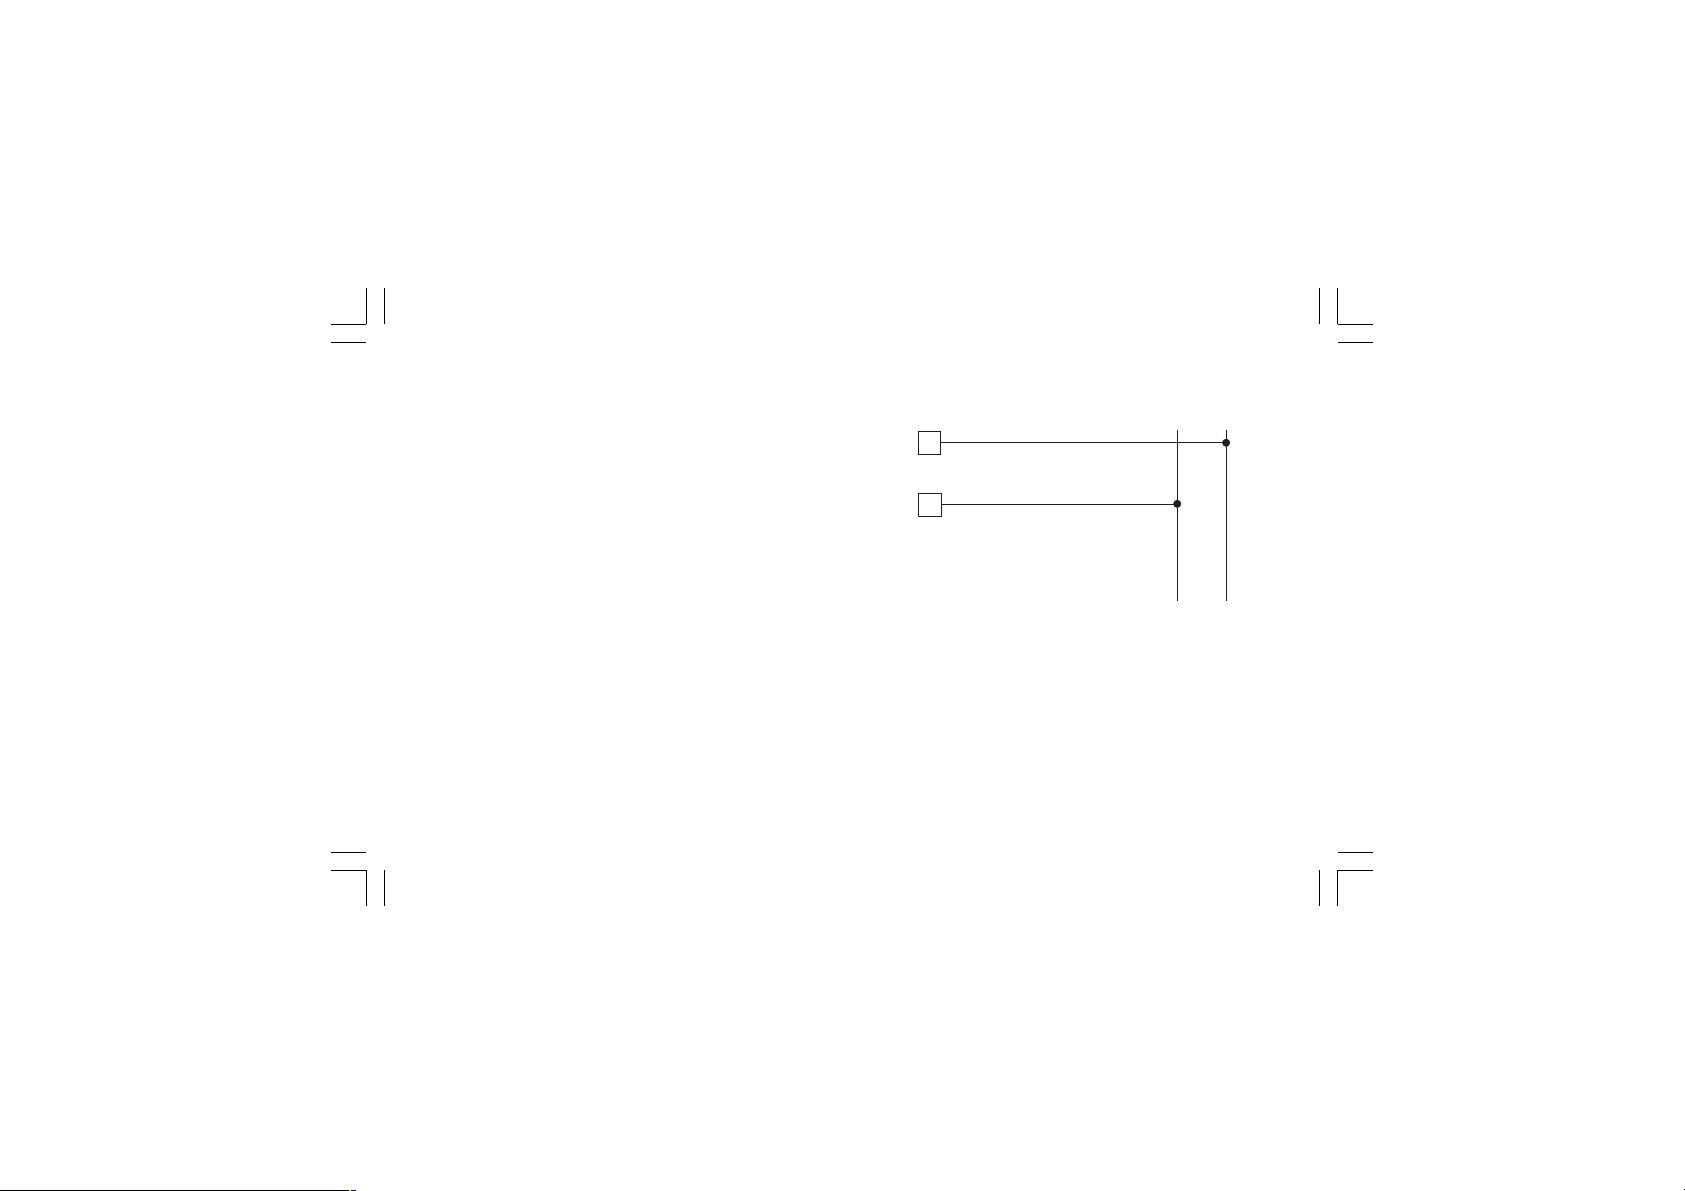
b) The ” A ” terminal of the generator shall be positive with
respect to the ” B ” terminal for a binary 0 (SPACE or ON).
4) The EIA standard establishes that by RS-485 interface it is
possible to connect up to 30 devices with one remote master
unit.
The serial interface of these instruments is based on “High
input impedance” transceivers; this solution allows you to
connect up to 127 devices (based on the same transceiver
type) with one remote master unit.
Xkc-1-C0.P65 5/29/02, 11:59 AM18
G) POWER LINE WIRING
N (L2)
32
POWER LINE 100 V to
240 V A.C (50/60Hz)
33
Fig. 18 POWER LINE WIRING
NOTES:
1) Before connecting the instrument to the power line, make sure
that line voltage corresponds to the description on the identification label.
2) To avoid electrical shock, connect power line at the end of the
wiring procedure.
3) For supply connections use No 16 AWG or larger wires rated for
at least 75 °C.
18
or 24 V AC/DC
L (L1)
Line
Neutral
Page 23
4) Use copper conductors only.
5) Don’t run input wires together with power cables.
6) For 24 V DC the polarity is a not care condition.
7) The power supply input is fuse protected by a sub miniature fuse
rated T, 1A, 250 V.
When fuse is damaged, it is advisable to verify the power supply
circuit, so that it is necessary to send back the instrument to your
supplier.
8) The safety requirements for Permanently Connected
Equipment say:
- a switch or circuit-breaker shall be included in the building
installation;
- it shall be in close proximity to the equipment and within
easy reach of the operator;
- it shall be marked as the disconnecting device for the
equipment.
NOTE: a single switch or circuit-breaker can drive more than one
instrument.
9) When a neutral line is present please connect it to the 32
terminal.
PRELIMINARY HARDWARE SETTINGS
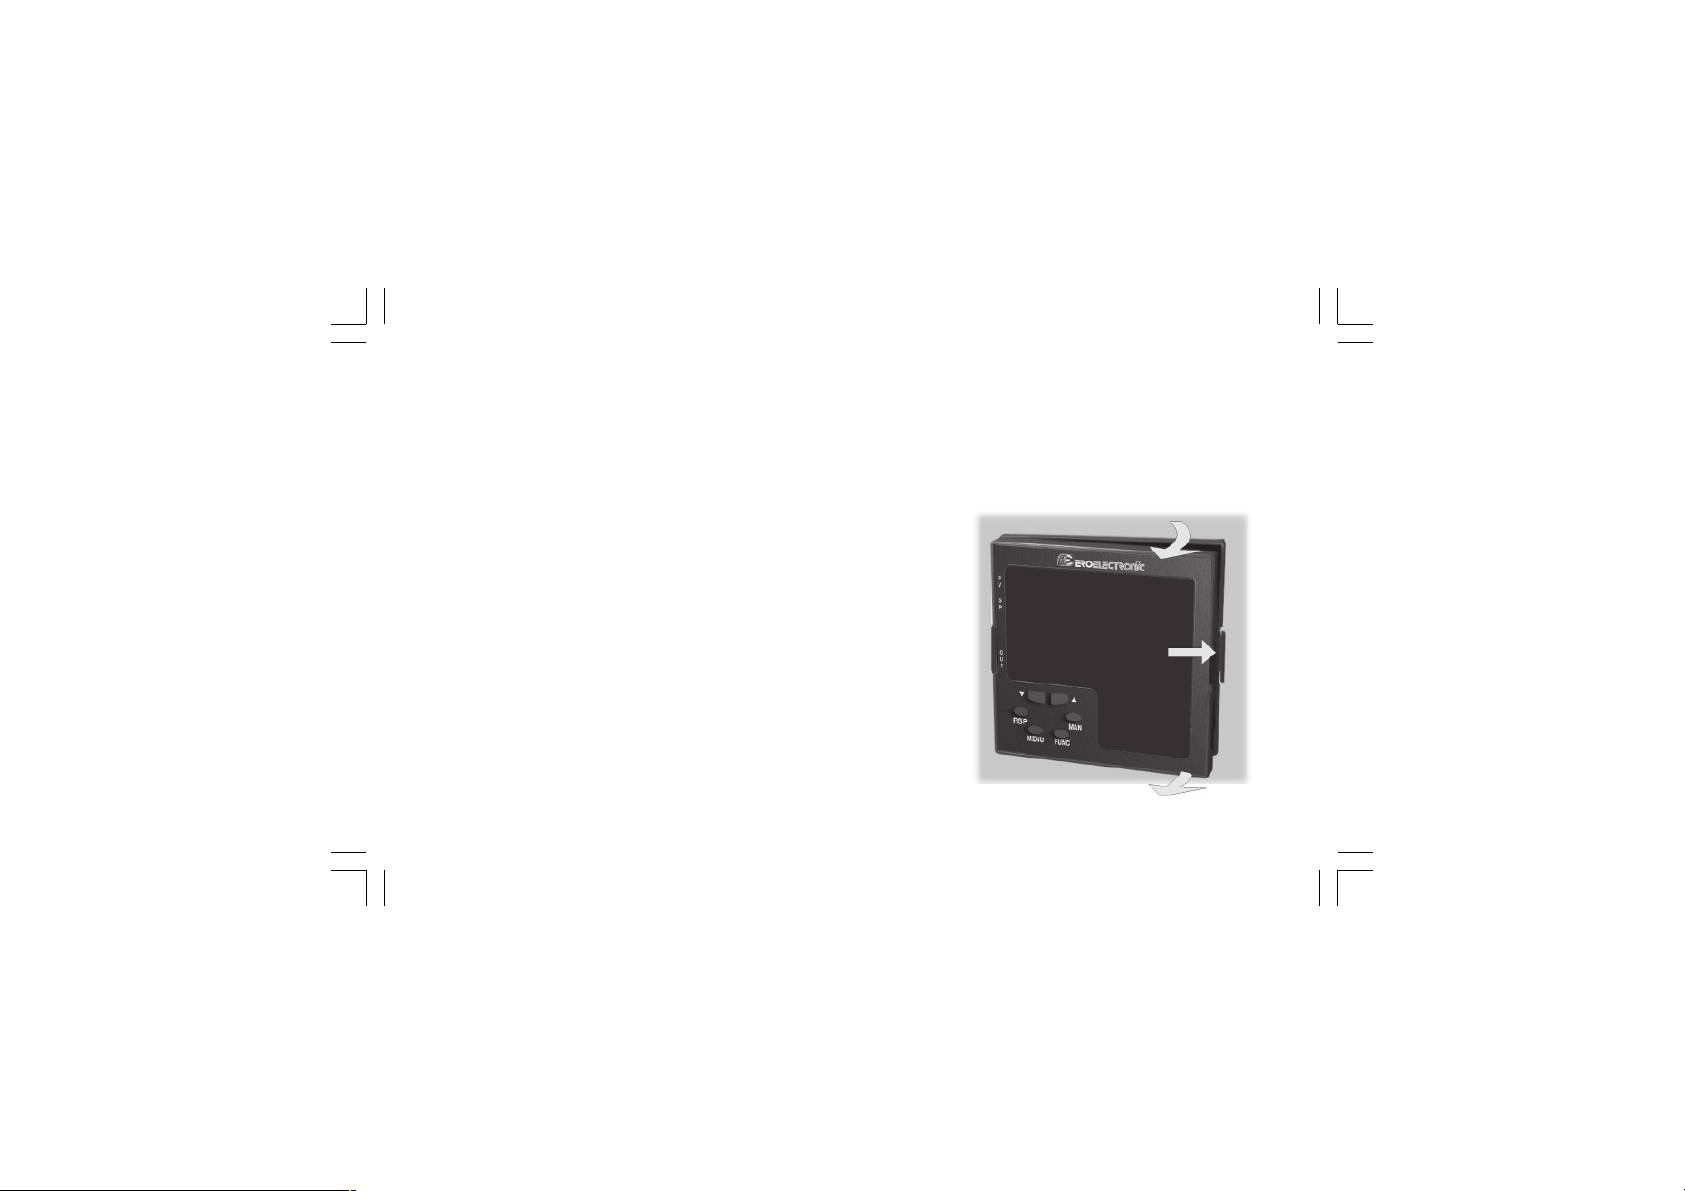
How to remove the instrument from its case
1) Switch off the instrument.
2) Push gently the lock A on the right.
3) While the lock A is maintained out, slide out the right side of
the instrument (see fig. 19.a)
B
A
Xkc-1-C0.P65 5/29/02, 11:59 AM19
19
Fig. 19.a
B
Page 24
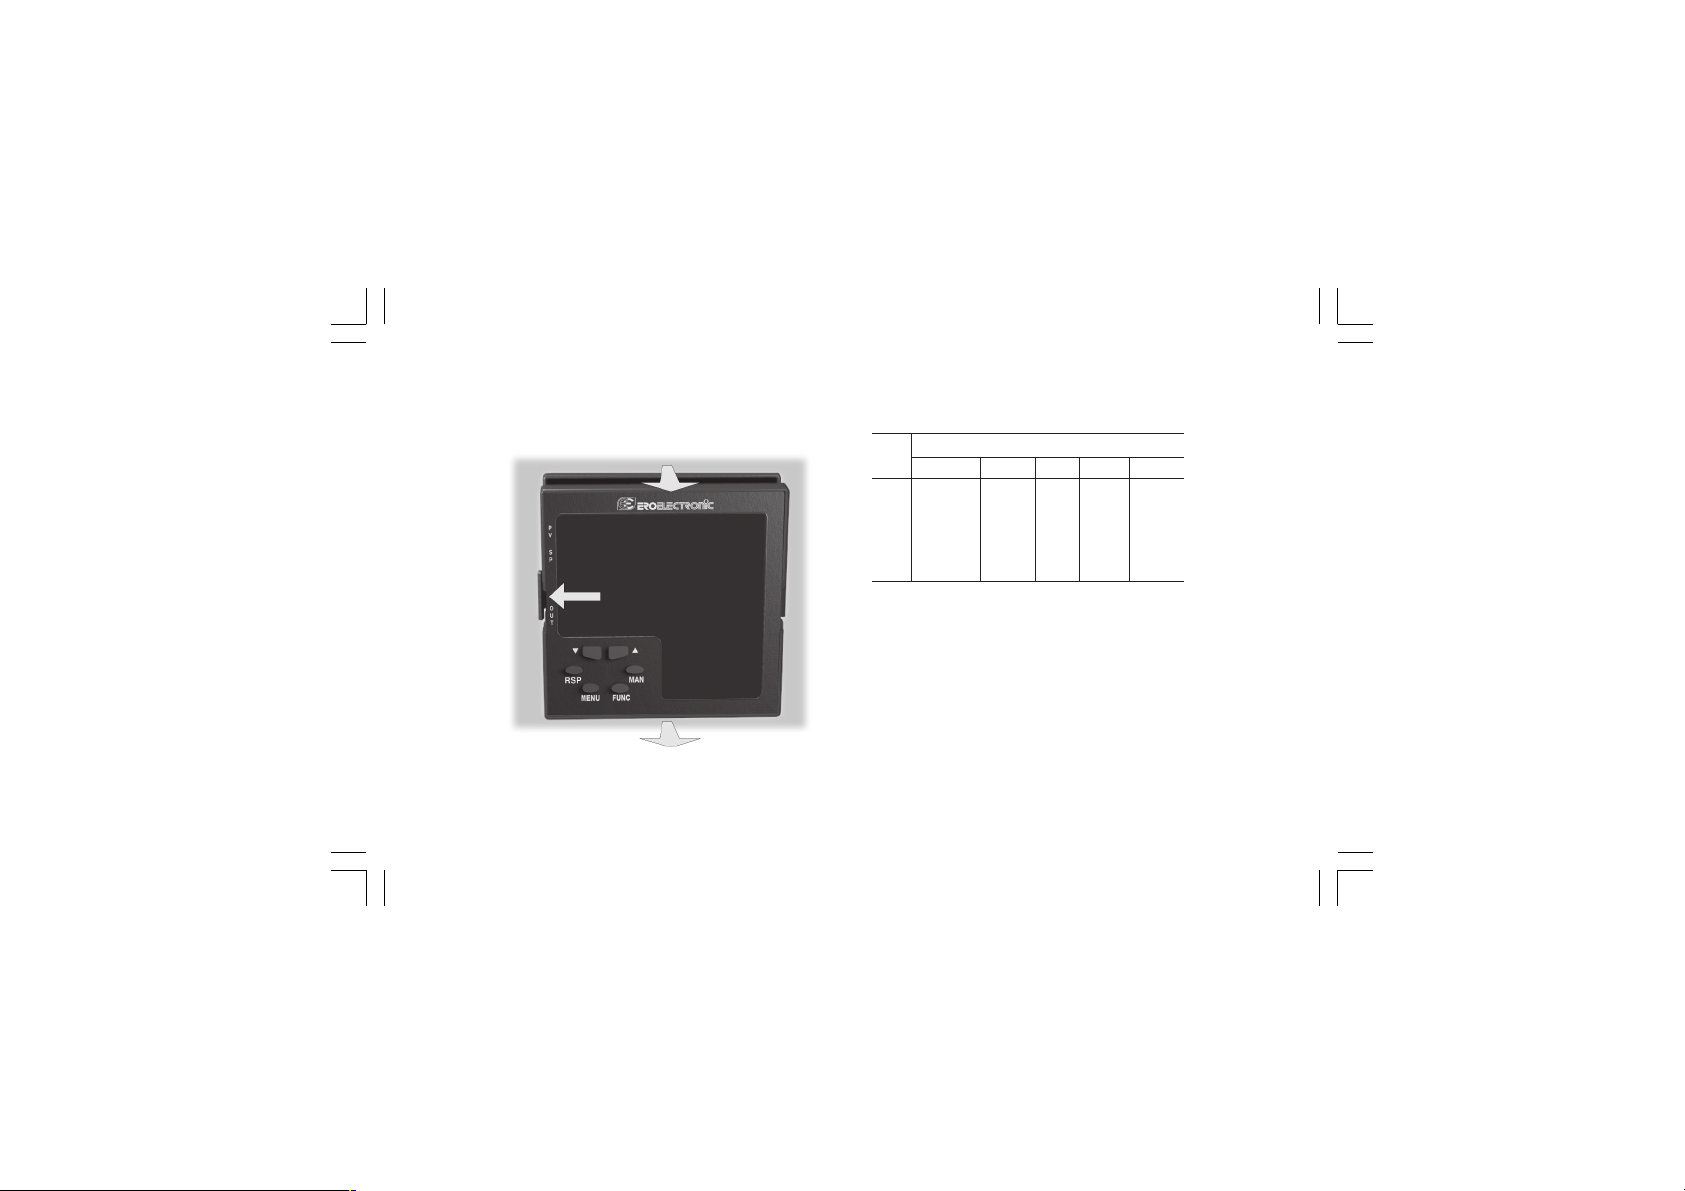
4) Push gently the lock C on the left.
5) While the lock C is maintained out, slide out the instrument
(see fig. 19.b)
MAIN INPUT SELECTION
Set J103 (see fig. 20) according to the desired input type as
shown in the following table.
C
Fig. 19.b
Xkc-1-C0.P65 5/29/02, 11:59 AM20
D
J103 INPUT TYPE
T/C, RTD 60 mV 5 V 10 V 20 mA
1-2 open open close open open
3-4 open open close close open
5-6 open open open open close
7-8 open open open open close
5-7 close close open close open
6-8 close close open open open
D
20
Page 25
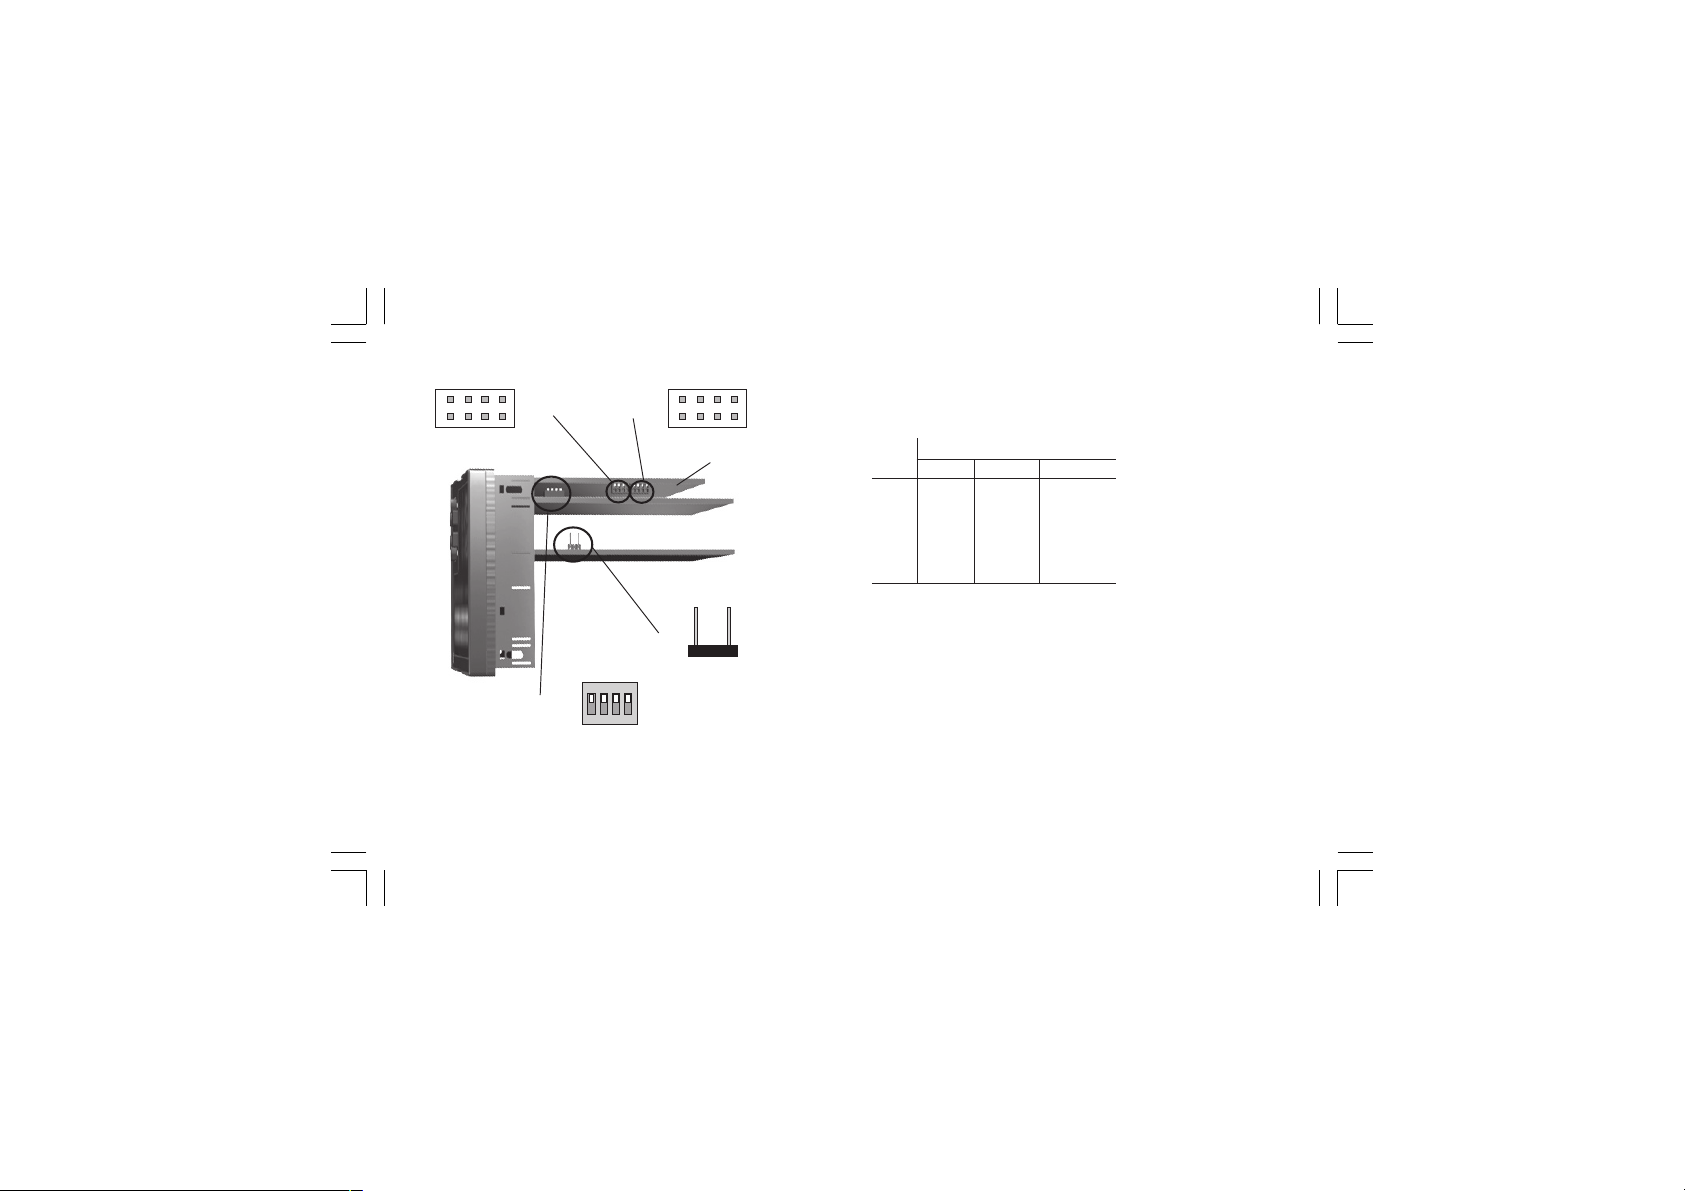
1 3 5 7
J102
2 4 6 8
J103
J205
ON DIP
V301
1 2 3 4
Fig. 20
Xkc-1-C0.P65 5/29/02, 11:59 AM21
1 3 5 7
2 4 6 8
CPU
card
AUXILIARY INPUT SELECTION (option)
Set J102 (see fig. 20) according to the desired input type as
shown in the following table.
J102 INPUT TYPE
5 V 10 V 20 mA
1-2 close open open
3-4 close close open
5-6 open open close
7-8 open open close
5-7 open close open
6-8 open open open
21
Page 26
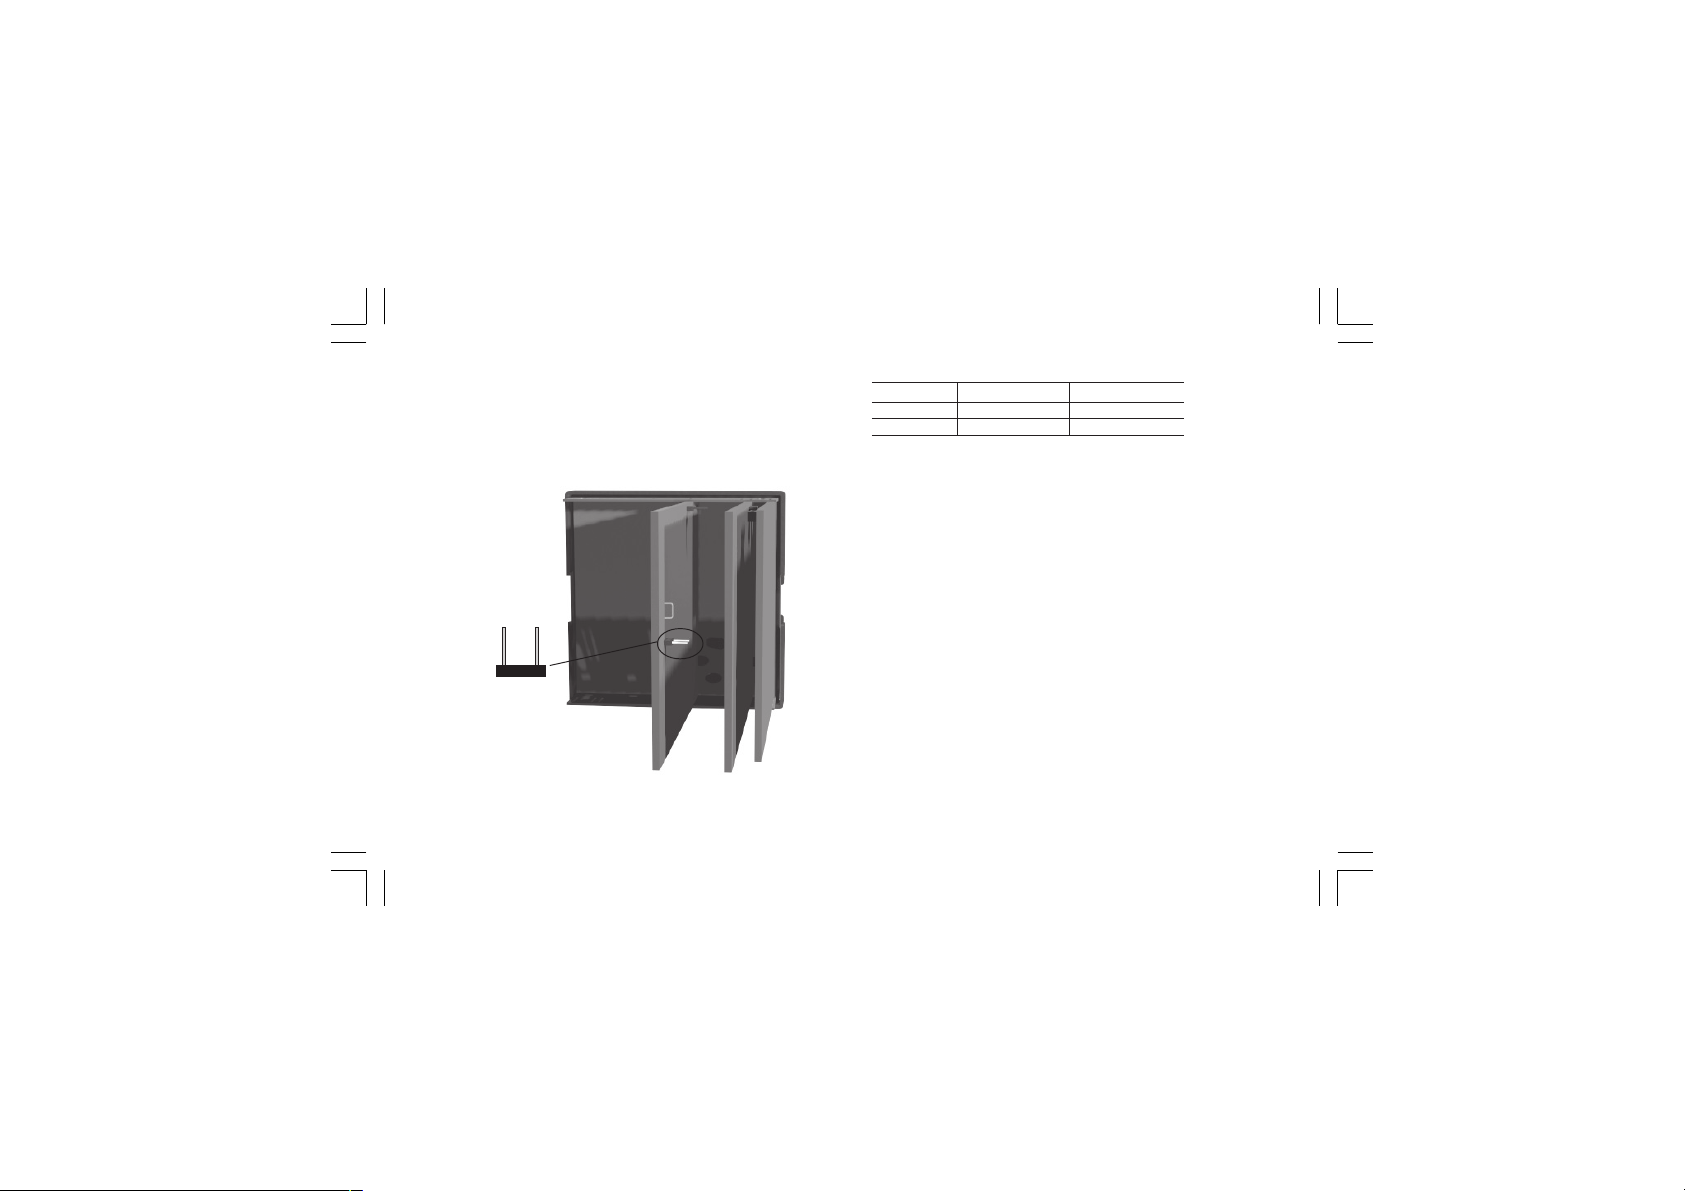
OUTPUT 3 AND 4 SELECTION
Output 3 and 4 can be set as:
- 2 independent relay outputs
- 1 servomotor output with interlocked contact.
Set J204 (see fig. 21) and J205 (see fig. 20) according to the
desired output type as shown in the following table.
J204
Fig.21
Xkc-1-C0.P65 5/29/02, 11:59 AM22
Output J 204 J 205
Relay close open
Servo open close
NOTE: when the servomotor close loop or the servomotor open
loop with valve position indication outputs is required, it will be
necessary to set also V301 (see "IN CT/Feedback selection"
paragraph)
IN CT / FEEDBACK SELECTION
This instrument can use the "IN CT" input or the "Feedback"
input; the two inputs are not contemporarily.
The current transformer input allows you to measure and display
the current running in a load driven by a time proportional control
output during the ON and OFF periods of the output cycle time.
By this feature it is also available the "Out failure detection"
function (see page 66).
The feedback input is used when the servomotor close loop or
the servomotor open loop with valve position indication outputs
is required.
22
Page 27
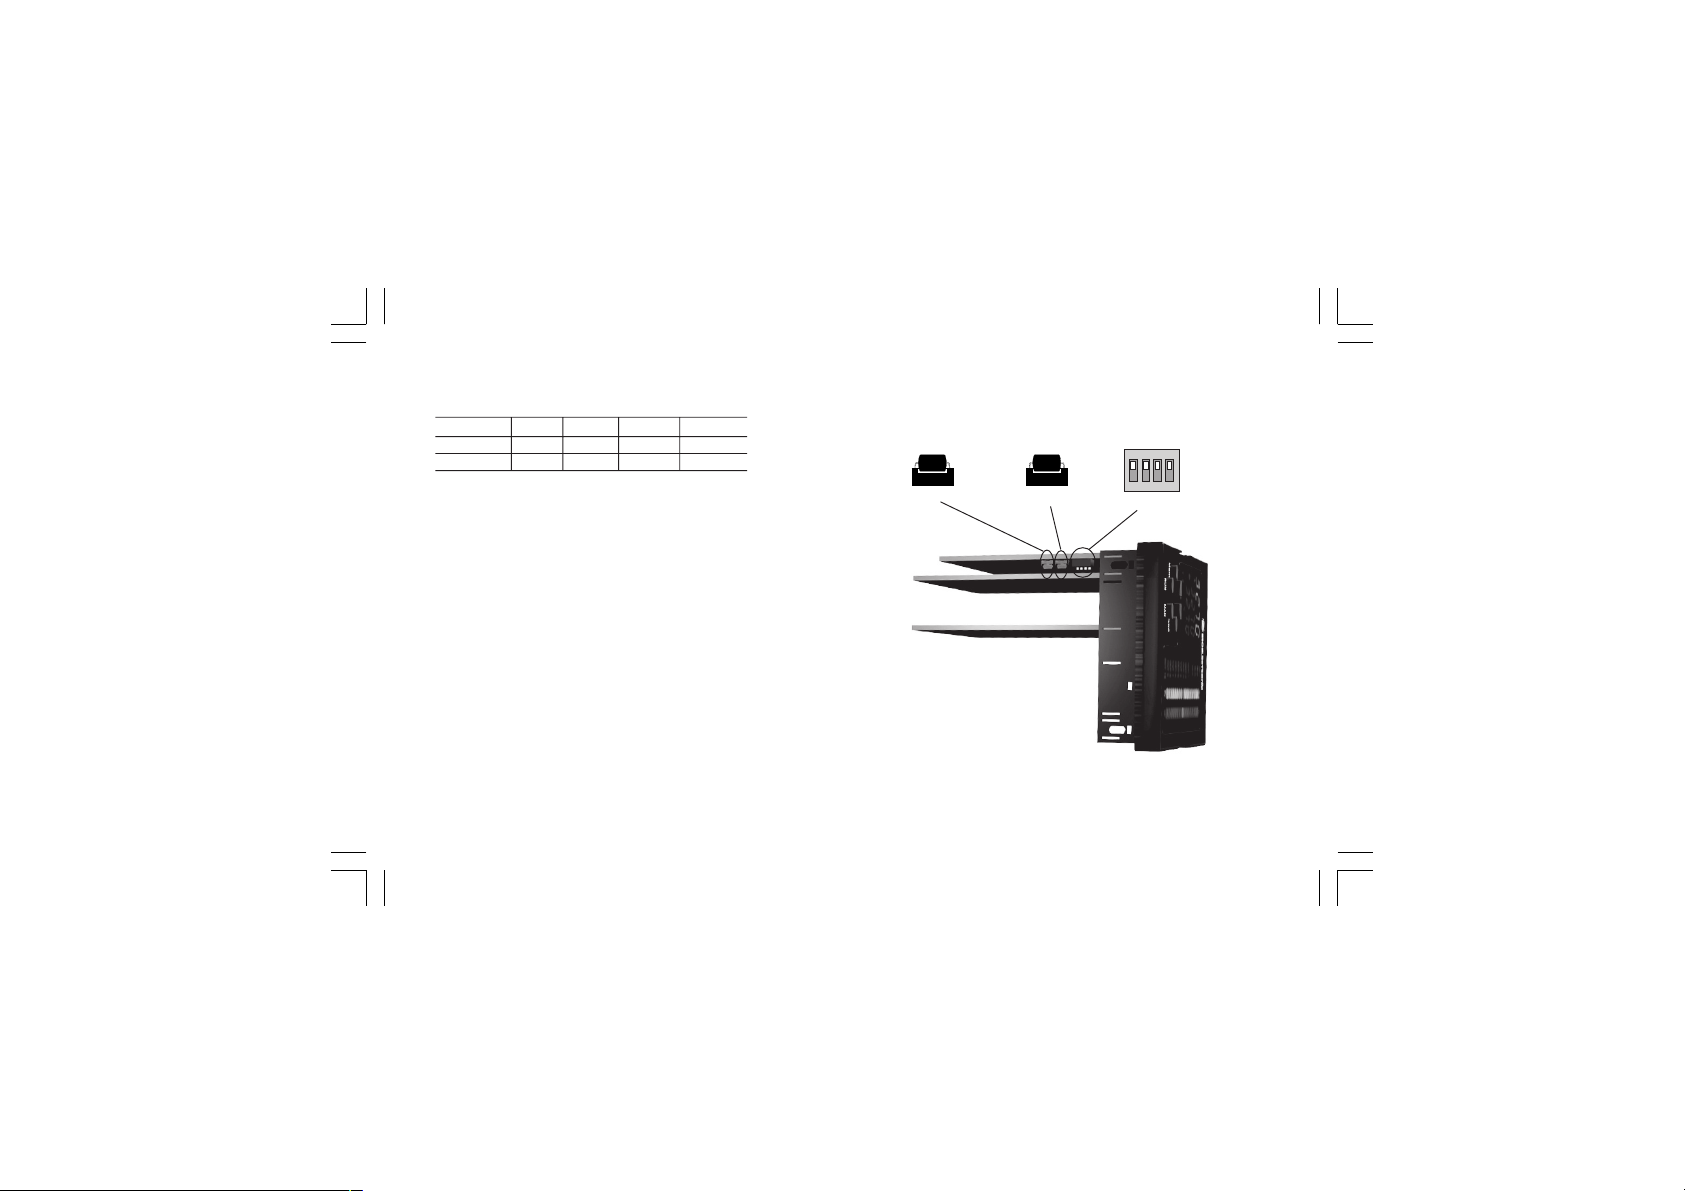
To select the desired input type, set V301 (see fig. 20) as
detailed in the following table:
Input V301.1 V301.2 V301.3 V301.4
IN CT ON OFF ON ON
Feedback OFF ON OFF ON
OPTION CHECK
This instrument can be supplied with many options.
Two integrated circuits (KY101 and KY103), located as shown in
fig. 22 and inserted in a socket, give you the possibility to verify
if your instrument is equipped with the desired option.
When KY101 is present the auxiliary input and the digital inputs
are present.
When KY103 is present the auxiliary power supply option is
present.
Xkc-1-C0.P65 5/29/02, 11:59 AM23
ON DIP
KY101
KY103
1 2 3 4
V101
Fig. 22
23
Page 28
Operative mode and Hardware lock
1) By V101 (see fig 22) it is possible to select one of the
following operative modes:
a) run time mode without configuration mode
b) run time and configuration modes
c) security code setting mode
Set V101 according to the following table:
Modes V101.1 V101.2 V101.3 V101.4
a OFF ON ON ON
b OFF ON OFF ON
c OFF ON OFF OFF
2) When run time mode is selected (mode a or b), V101.3
allows you to activate/deactivate the hardware lock for
configuration parameters.
If V101.3 is ON, the lock is activated.
If V101.3 is OFF, the lock is deactivated.
When the lock is activated, no one of the configuration
parameter can be modifyed.
3) All the others switch combinations are reserved.
Xkc-1-C0.P65 5/29/02, 11:59 AM24
SECURITY CODE SETTING MODE
General notes
The instrument parameters are divided in two families and
each family is divided in groups.
- The first family encompasses all the run time parameters.
- The second family comprises all the configuration
parameters.
A specific security code enables the parameter modification of
each family.
For run time parameters, it is possible to select which groups
of them will be protected by the security code and in this case
it is necessary to set the run time security code before to
modify one or more parameters of a protected group.
The configuration security code protects all configuration
parameters and it will be necessary to set the configuration
security code before to start the configuration parameters
modification.
For configuration parameters an hardware lock is also
available.
24
Page 29
Security code setting:
1) Remove the instrument from its case.
2) Set the internal dip switch V101 as follows:
- V101.1 = OFF- V101.2 = ON
- V101.3 = OFF- V101.4 = OFF
3) Re-insert the instrument.
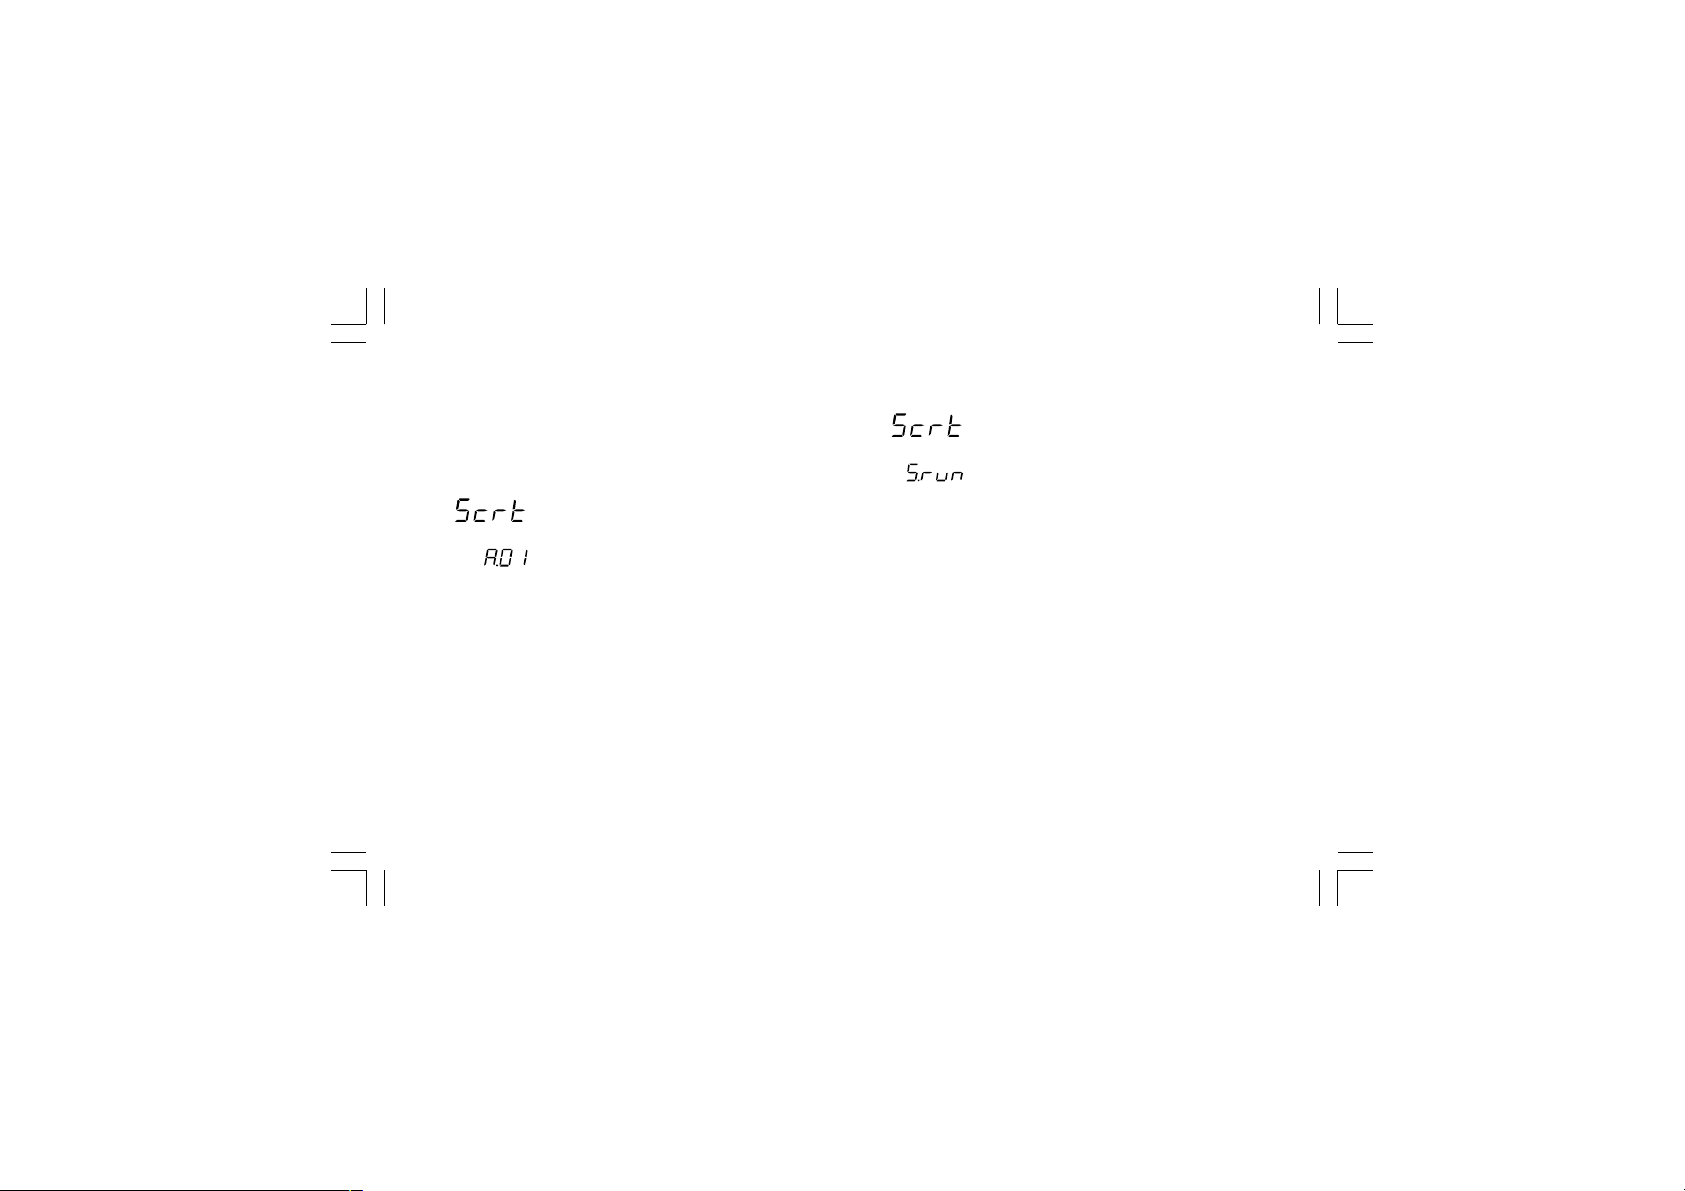
4) Switch on the instrument. The display will show:
The upper display shows that the security code setting mode
is selected while the lower display shows the firmware
version.
5) Push the FUNC pushbutton.
Xkc-1-C0.P65 5/29/02, 11:59 AM25
Run time security code
The display will show:
Note: the middle display shows the current status of the run time
security code ("0", "1" or "On").
By s and t push-button, set "S.run" parameter as follows:
0 No protection (it is ever possible to modify all run time
parameters);
1 ever protected (it is never possible to modify a run time
parameter);
from 2 to 250 security code for run time parameter protection.
NOTES:
1) the selected value of a security code cannot be displayed
anymore and, coming back to the "S.run" parameter, the
display will show "On" when "S.run" is different from 0 or 1,
"0" when "S.run" is equal to 0, "1" when "S.run" is equal to 1.
When the security code is forgotten, a new value can be set.
2) When "S.run" is different from 0 or 1, the "run time default "
and the "run time hidden" groups are ever protected by
security code.
25
Page 30
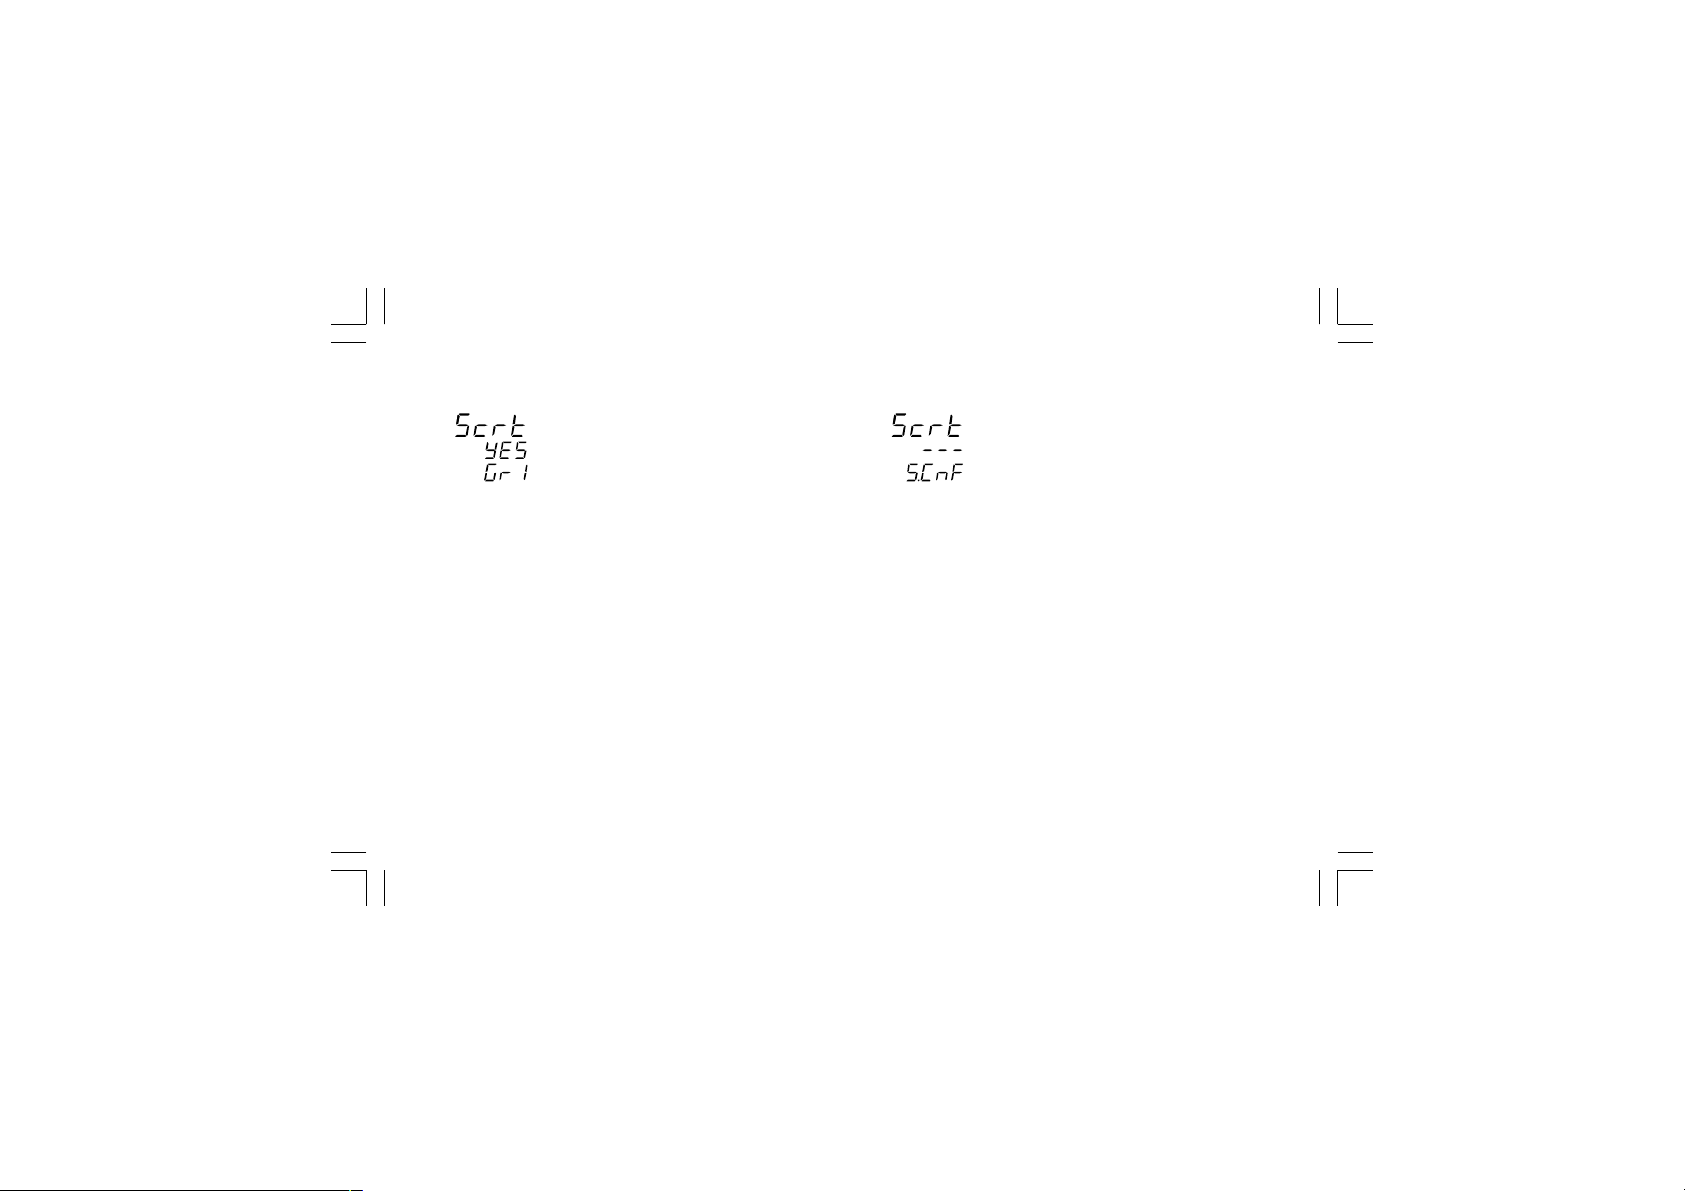
Run time groups protected by security code
The display will show:
Configuration security code
The display will show:
By this parameter it is possible to set if the run time group 1 will
be protected or not by the run time security code.
By s and t push-button, set "Gr1" parameter as follows:
nO No protection (it is always possible to modify run time
group 1 parameters)
Yes the run time group 1 parameter modification will be
protected by security code.
Push the FUNC push-button; the instrument memorizes the new
setting and goes to the next parameter.
NOTE: the above described selection may be repeated for all
groups of the run time mode.
Xkc-1-C0.P65 5/29/02, 11:59 AM26
Note: the middle display shows the actual status of the
configuration security code ("0", "1" or "On").
By s and t push-button, set "S.CnF" parameter as follows:
0 No protection (it is ever possible to modify all
configuration parameters);
1 ever protected (it is never possible to modify a
configuration parameter);
from 2 to 250 security code for configuration parameter
protection.
NOTE: the selected value of a security code cannot be
displayed anymore and, coming back on the "S.CnF"
parameter, the display will show "On" when "S.CnF" is
different from 0 or 1, "0" when "S.CnF" is equal to 0,
"1" when "S.CnF" is equal to 1.
When the security code is forgotten, a new value can
be set.
26
Page 31
RUN TIME AND CONFIGURATION MODES
The hardware selection described in "Operative mode and
hardware lock" paragraph allows you to start one of the two
following operative modes:
- run time mode
- configuration mode.
At power up, the instrument starts in the same mode it was prior
to the power OFF.
General note about graphic symbols used for mnemonic
code visualization.
The instrument displays some characters with special symbols.
The following table shows the correspondence between the
symbols and the characters
Xkc-1-C0.P65 5/29/02, 11:59 AM27
symbol character
"
"k
"
"m
" "V
" "W
"
"Z
" "J
Keyboard description
MENU = is used to select a parameter group
FUNC = o when the instrument is in "normal display mode" it
changes the indication on the lower display (see
"display function").
o During parameter modification, it allows you to
memorize the new value of the selected parameter
and go to the next parameter (increasing order).
MAN = o when the instrument is in "normal display mode",
pushing MAN push-button for more than 1 s, it is
possible to enable or disable the manual function.
o During parameter modification, it allows you to scroll
back the parameters and groups without memorizing the new setting.
s = o During parameter modification, it allows you to
increase the value of the selected parameter
o During MANUAL mode, it allows you to increase the
output value.
27
Page 32
t = o During parameter modification, it allows you to
decrease the value of the selected parameter
o During MANUAL mode, it allows to decrease the
output value.
RSP = allows to toggle from Local set point to Remote set
point or viceversa when depressed for more than 1
sec.
t+MENU= are used to start the lamp test function (the
command is accepted when push-button are kept
depressed for more than 5 s and device is in normal
display mode)
s+FUNC or t+FUNC
During parameter modification they allow you to
increase/decrease the value under modification with
higher rate.
s+MAN or t+MAN
During parameter modification they allow you to
jump to the max or min programmable value.
Xkc-1-C0.P65 5/29/02, 11:59 AM28
NOTES:
1) All the actions explained above which requires two or more
push-buttons must follow exactly the push-button sequence
shown.
2) A 10 or 30 seconds time out (see "t.out" [C.I10]) can be
selected for parameter modification during run time mode.
If, during parameter modification, no push-button is
depressed for more than 10 (30) seconds, the instrument
goes automatically to the “normal display mode” and the
eventual modification of the last parameter will be lost.
28
Page 33
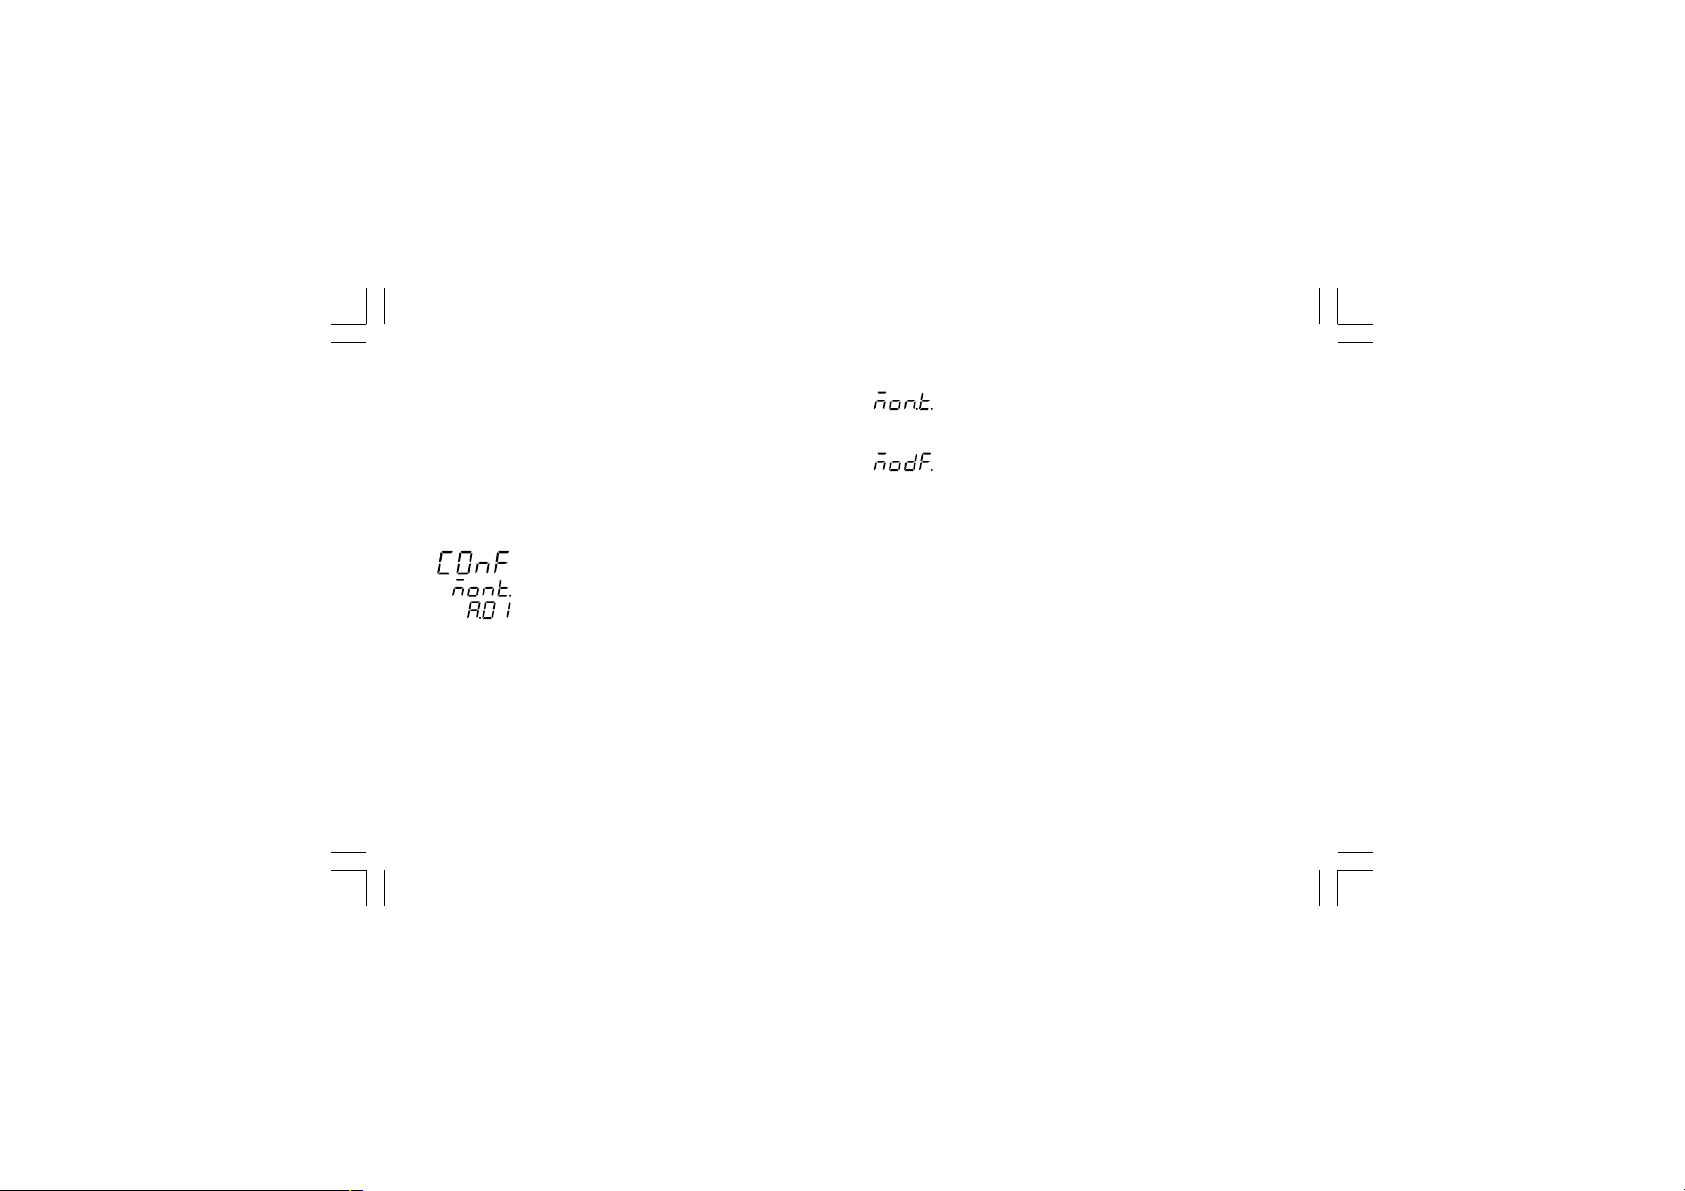
CONFIGURATION MODE
Switch on the instrument.
The instrument will start in the same way it was prior to the
power down (configuration mode or run time mode)
If the instrument starts in configuration mode, push the MENU
pushbutton and go to the "Configuration group 1" (see page 30).
If the instrument starts in run time mode, by keeping depressed
the MENU push-button for more than 5 seconds the instrument
will show:
NOTES:
1) The upper display shows the selected parameter family.
2) The middle display shows the selected action.
3) The lower display shows the firmware version.
4) If no push-button is depressed for more than 10 s (or 30 s
according to "CnF.6" "t.out" [time out selection" C.I10]
parameter setting), the instrument returns automatically to the
normal display mode.
Xkc-1-C0.P65 5/29/02, 11:59 AM29
By s or t push-button it is possible to select between:
= (monitor) this selection allows you to monitor but
not to modify the value assigned to the configuration parameters
= (modify) this selection allows you to monitor and
to modify the value assigned to the configuration
parameters.
NOTES:
1) During monitor mode, the instrument continues to operate as
in run time mode.
2) When modify mode is started, the instrument stops the
control and:
- sets control outputs to OFF;
- turns OFF the bargraph displays (MKC only);
- sets analog retransmissions to the retransmitted initial
scale value;
- sets alarms in no alarm condition;
- sets events to OFF;
- disables the serial link;
- the time out will be removed.
3) When the modify mode is disabled by V101 (V101.3), the s
or t push-button pressure has no effect.
29
Page 34
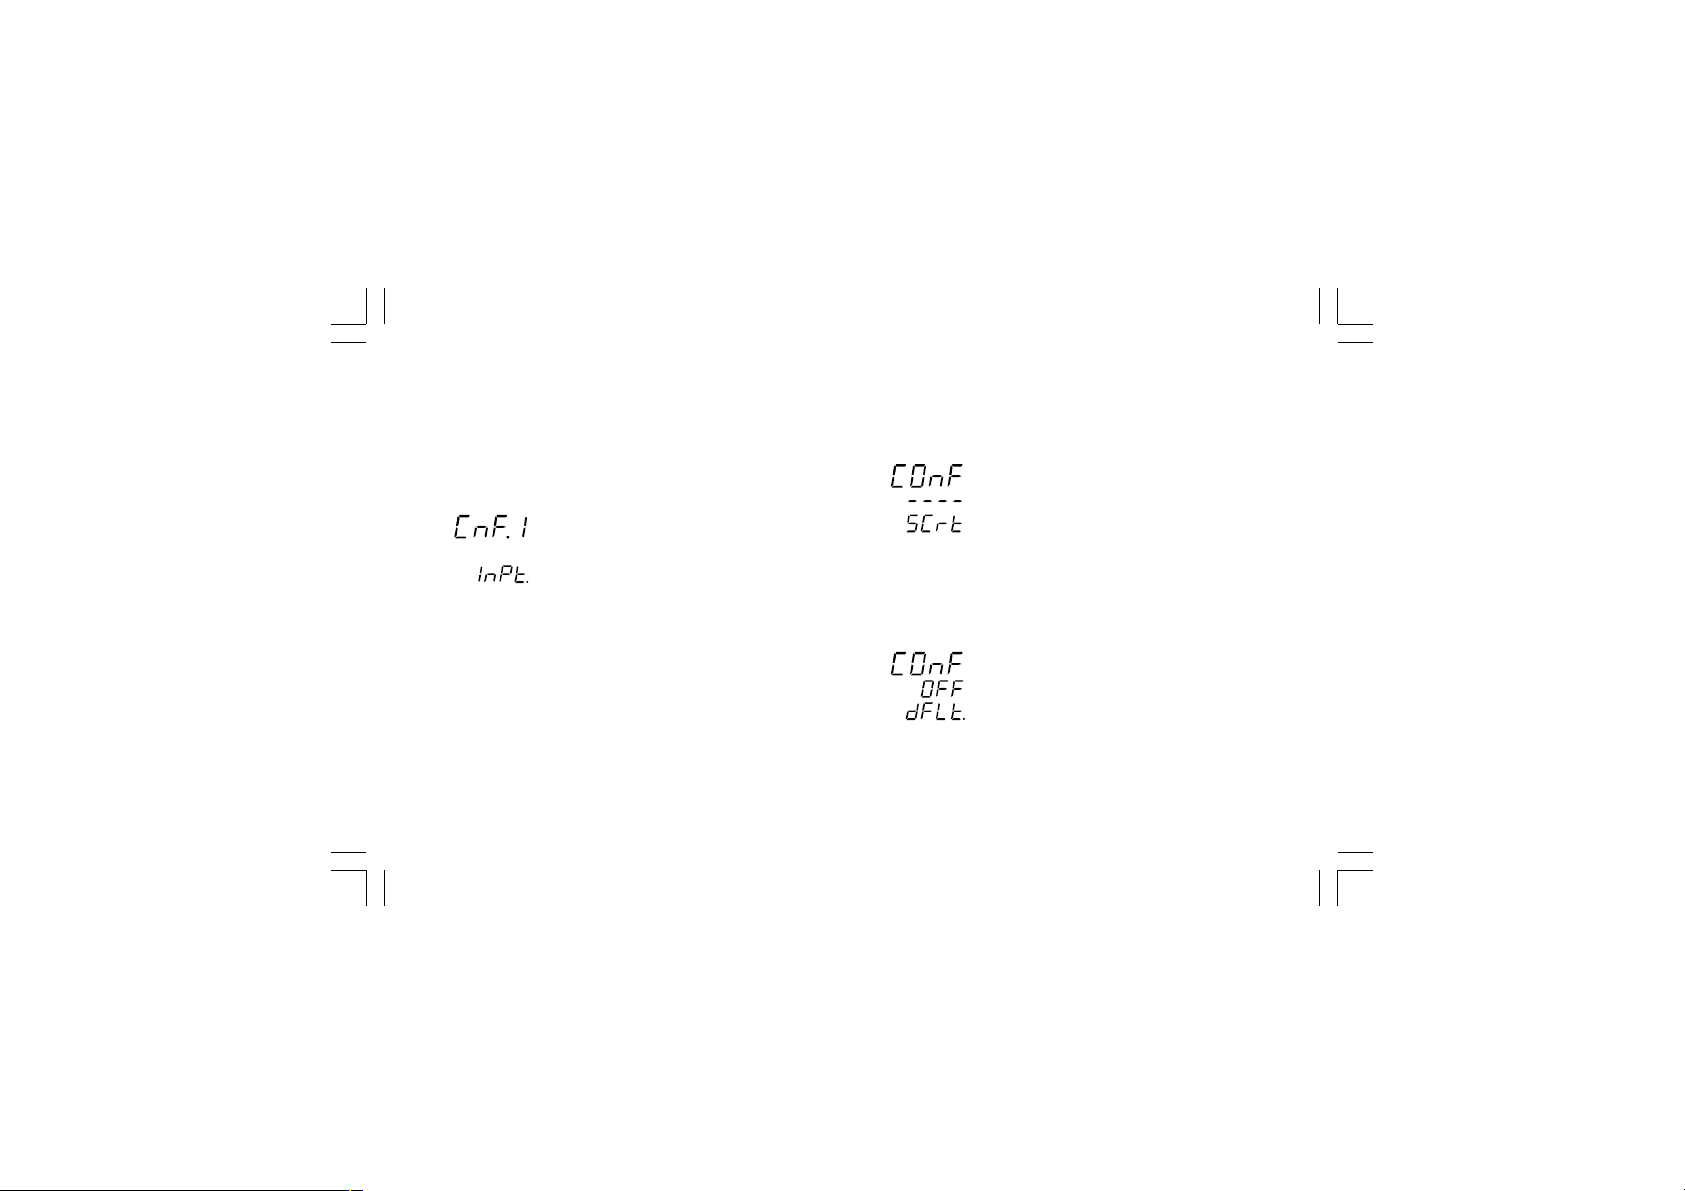
MONITOR MODE
During the run time mode, it is possible to monitor but not modify
all configuration parameters.
When it is desired to verify the instrument configuration, proceed
as follows:
1) By s or t push-button select the monitor mode.
2) Push the MENU push-button the display will show:
it shows that configuration group 1 is selected and it
encompass all the input parameters.
The configuration parameter "Monitor mode" follows the "Modify
mode" sequence.
NOTES:
1) During monitor mode, the instrument continues to operate as
in run time mode.
2) During monitor mode, if no push-button is depressed for more
than 10 s (or 30 s according to "t.out" [C.I10] parameter
setting), the instrument returns automatically to the normal
display mode.
Xkc-1-C0.P65 5/29/02, 11:59 AM30
MODIFY MODE
1) By s or t push-button select the modify mode.
2) Push the MENU push-button.
If a security code is applied to the configuration parameter,
the instrument will show:
3) By s and t push-button set a value equal to the security
code assigned to the configuration mode (see "Configuration
security code " at page 24).
If the code is different from the security code, the instrument
automatically returns to the first configuration display
otherwise the display will show:
30
Page 35
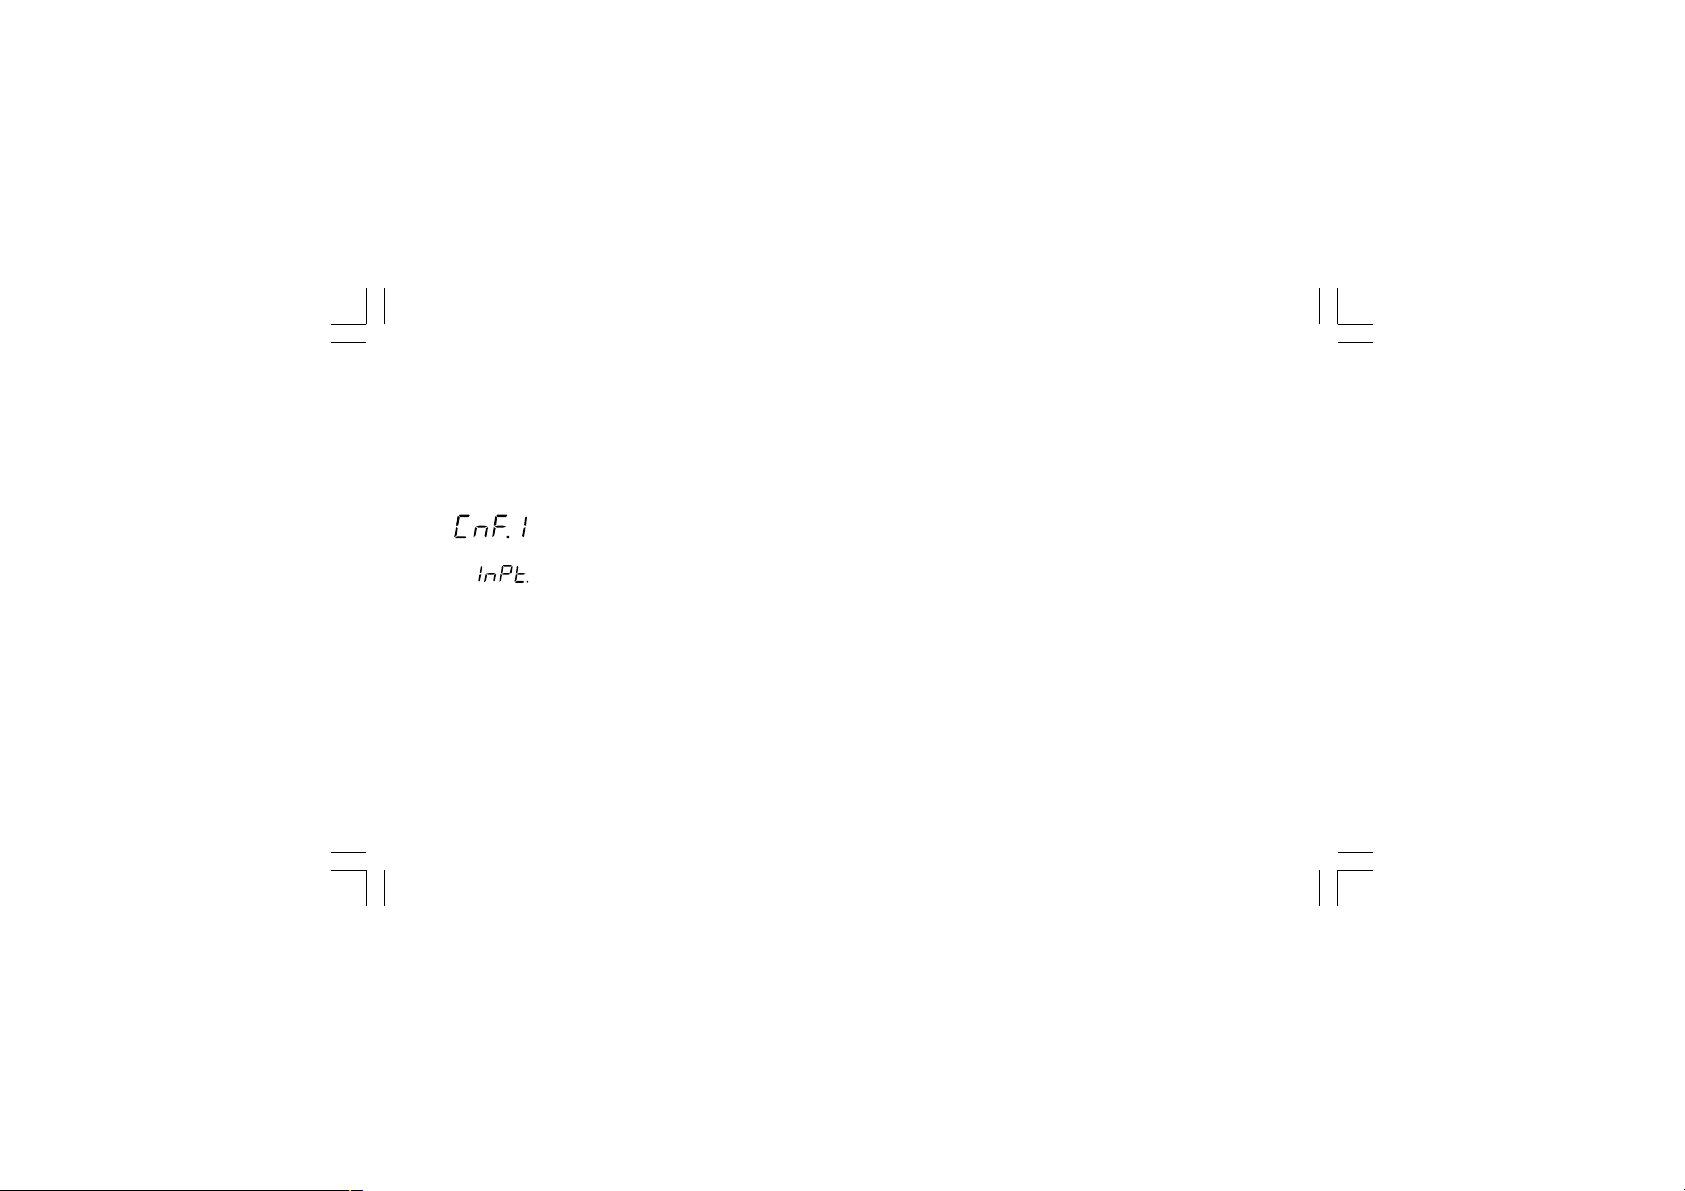
The modify mode is started.
This display allows you to load the default configuration
parameter.
For more details see chapter "Default parameter" (see
Appendix A).
4) By s or t push-button select the OFF indication and push
the MENU push-button.
The display will show:
This is the starting display of the first group of configuration
parameters.
NOTES:
1) In the following pages we will describe all the parameters of
the instrument but the instrument will show only the
parameters related with the specific hardware and in
accordance with the specific instrument configuration (i.e.
setting OUT 3 different from servo, all the parameters related
with servomotor output will be skipped).
Xkc-1-C0.P65 5/29/02, 11:59 AM31
2) During configuration parameters modify mode, the upper
display shows the selected parameter group, the lower
display shows the mnemonic code of the selected parameter
while the central display shows the value or status assigned
to the selected parameter.
3) For an easy consultation of this manual, a table with all the
parameter visualizations is enclosed.
When it is desired to exit from configuration modify mode
proceed as follows:
a) Push "MENU" push-button until the "Configuration group END
is displayed.
b) Pushing ”s” or “t” push-button select the "YES" indication.
c) Push “MENU” push-button. The instrument terminates the
configuration modify mode, it preforms an automatic reset
and restarts in the run time mode.
31
Page 36
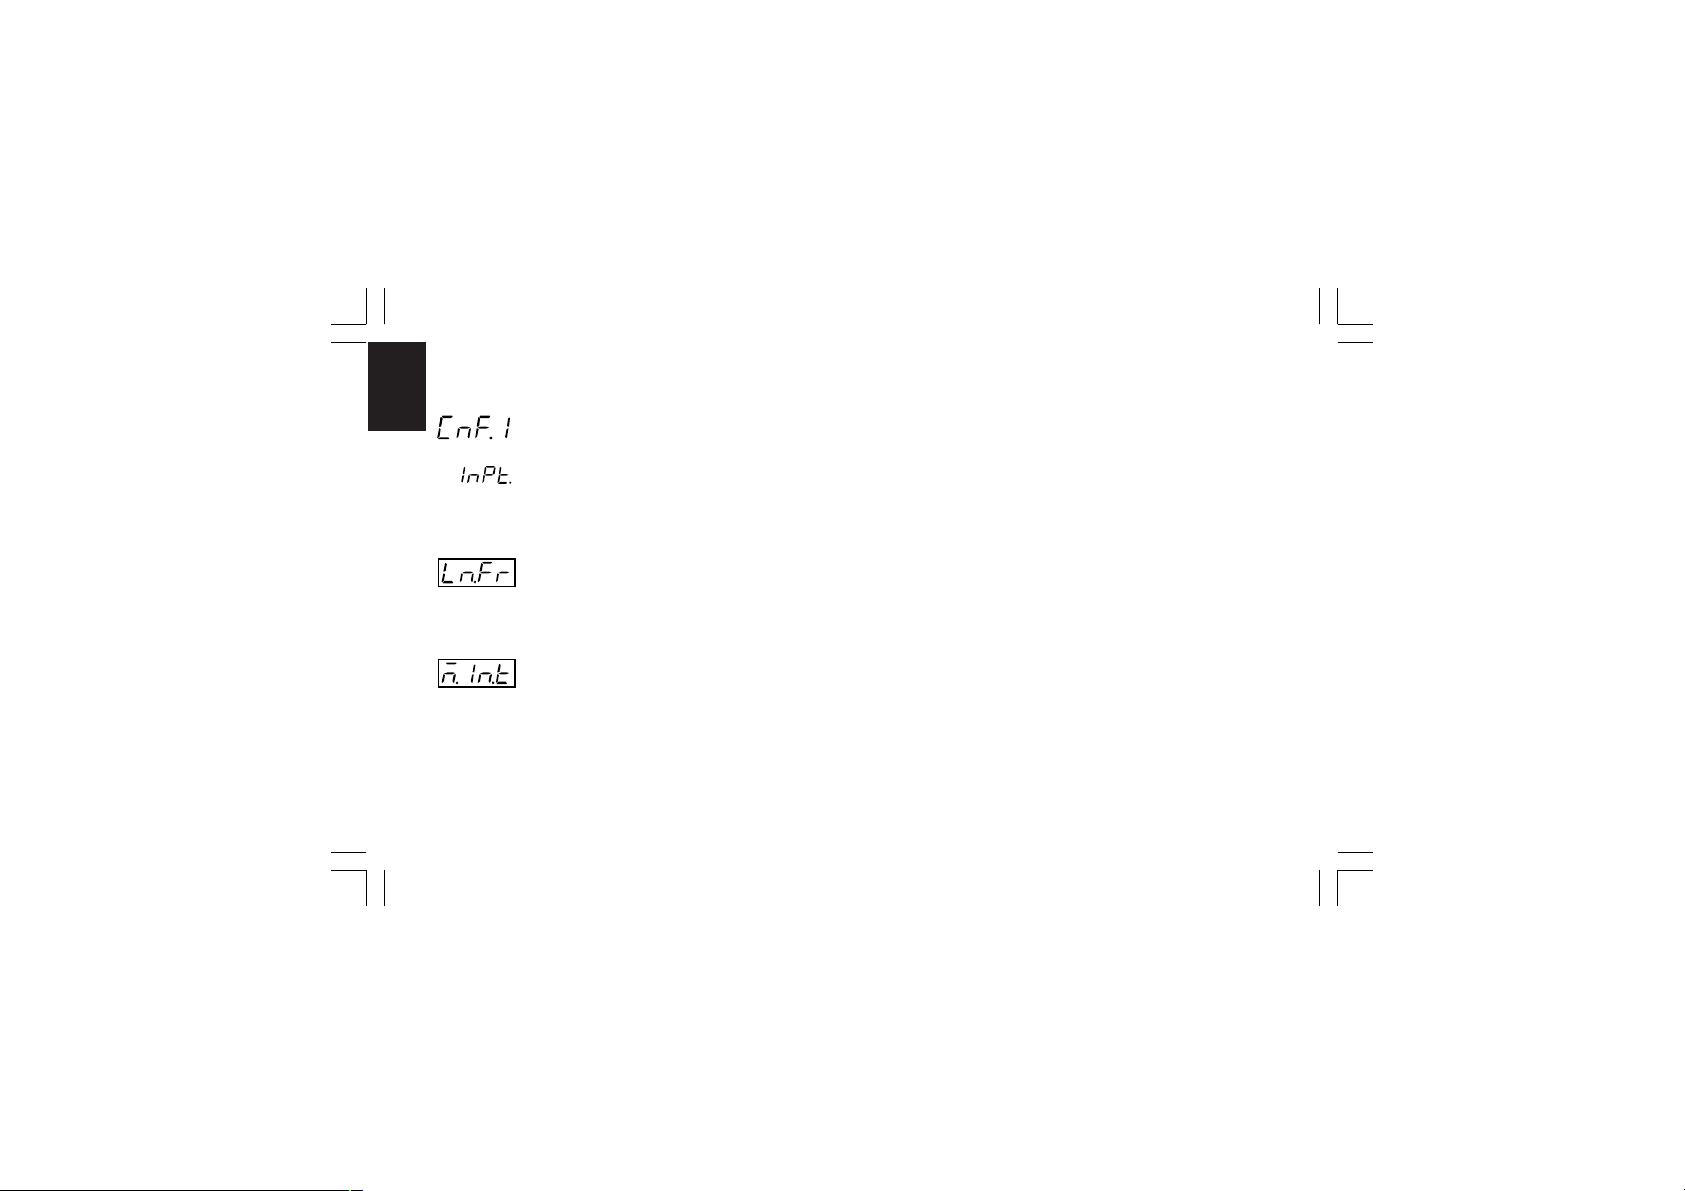
CONFIGURATION GROUP 1 [C.dxx]
MAIN AND AUXILIARY INPUT CONFIGURATION
CnF. 1
Push the FUNC push-button
- Line frequency - [C.d01]
Range: 50 Hz
60 Hz
- Main input type and range - [C.d02]
Ranges:
* 1 = TC L From -100 to 900 °C
* 2 = TC J From -100 to 1000 °C
* 3 = TC K From -100 to 1370 °C
* 4 = TC T From -200 to 400 °C
* 5 = TC U From -200 to 600 °C
Xkc-1-C0.P65 5/29/02, 11:59 AM32
* 6 = TC E From -100 to 800 °C
7 = TC N From -100 to 1400 °C
8 = TC S From - 50 to 1760 °C
9 = TC R From - 50 to 1760 °C
10 = TC B From 0 to 1820 °C
11 = TC G (or W) From 0 to 2300 °C
12 = TC D (or W3) From 0 to 2300 °C
13 = TC C (or W5) From 0 to 2300 °C
14 = TC Ni-Ni18%Mo From 0 to 1200 °C
* 15 = RTD Pt100 From -200 to 850 °C
16 = TC L From -150 to 1650 °F
17 = TC J From -150 to 1830 °F
18 = TC K From -150 to 2500 °F
19 = TC T From -330 to 750 °F
20 = TC U From -330 to 1110 °F
21 = TC E From -150 to 1470 °F
22 = TC N From -150 to 2550 °F
23 = TC S From - 60 to 3200 °F
24 = TC R From - 60 to 3200 °F
25 = TC B From 32 to 3300 °F
26 = TC G ( or W) From 0 to 4170 °F
27 = TC D (or W3) From 0 to 4170 °F
28 = TC C (or W5) From 0 to 4170 °F
29 = TC Ni-Ni18%Mo From 0 to 2190 °F
* 30 = RTD Pt100 From -330 to 1560 °F
32
Page 37
31 = Linear From 0 to 20 mA
32 = Linear From 4 to 20 mA
33 = Linear From 0 to 5 V
34 = Linear From 1 to 5 V
35 = Linear From 0 to 10 V
36 = Linear From 2 to 10 V
37 = Linear From 0 to 60 mV
38 = Linear From 12 to 60 mV
* For these ranges it is possible to select a read-out with one
decimal figure but the instrument could not display a measure
lower than -199.9 or higher than 999.9 and the input range
will be limited by it.
NOTES:
1) When a linear input is selected, the instrument set automatically the "readout initial scale value" [C.d05] equal to 0 and
the "readout final scale value" [C.d06] equal to 4000
2) When input type has been changed, the instrument
automatically forces:
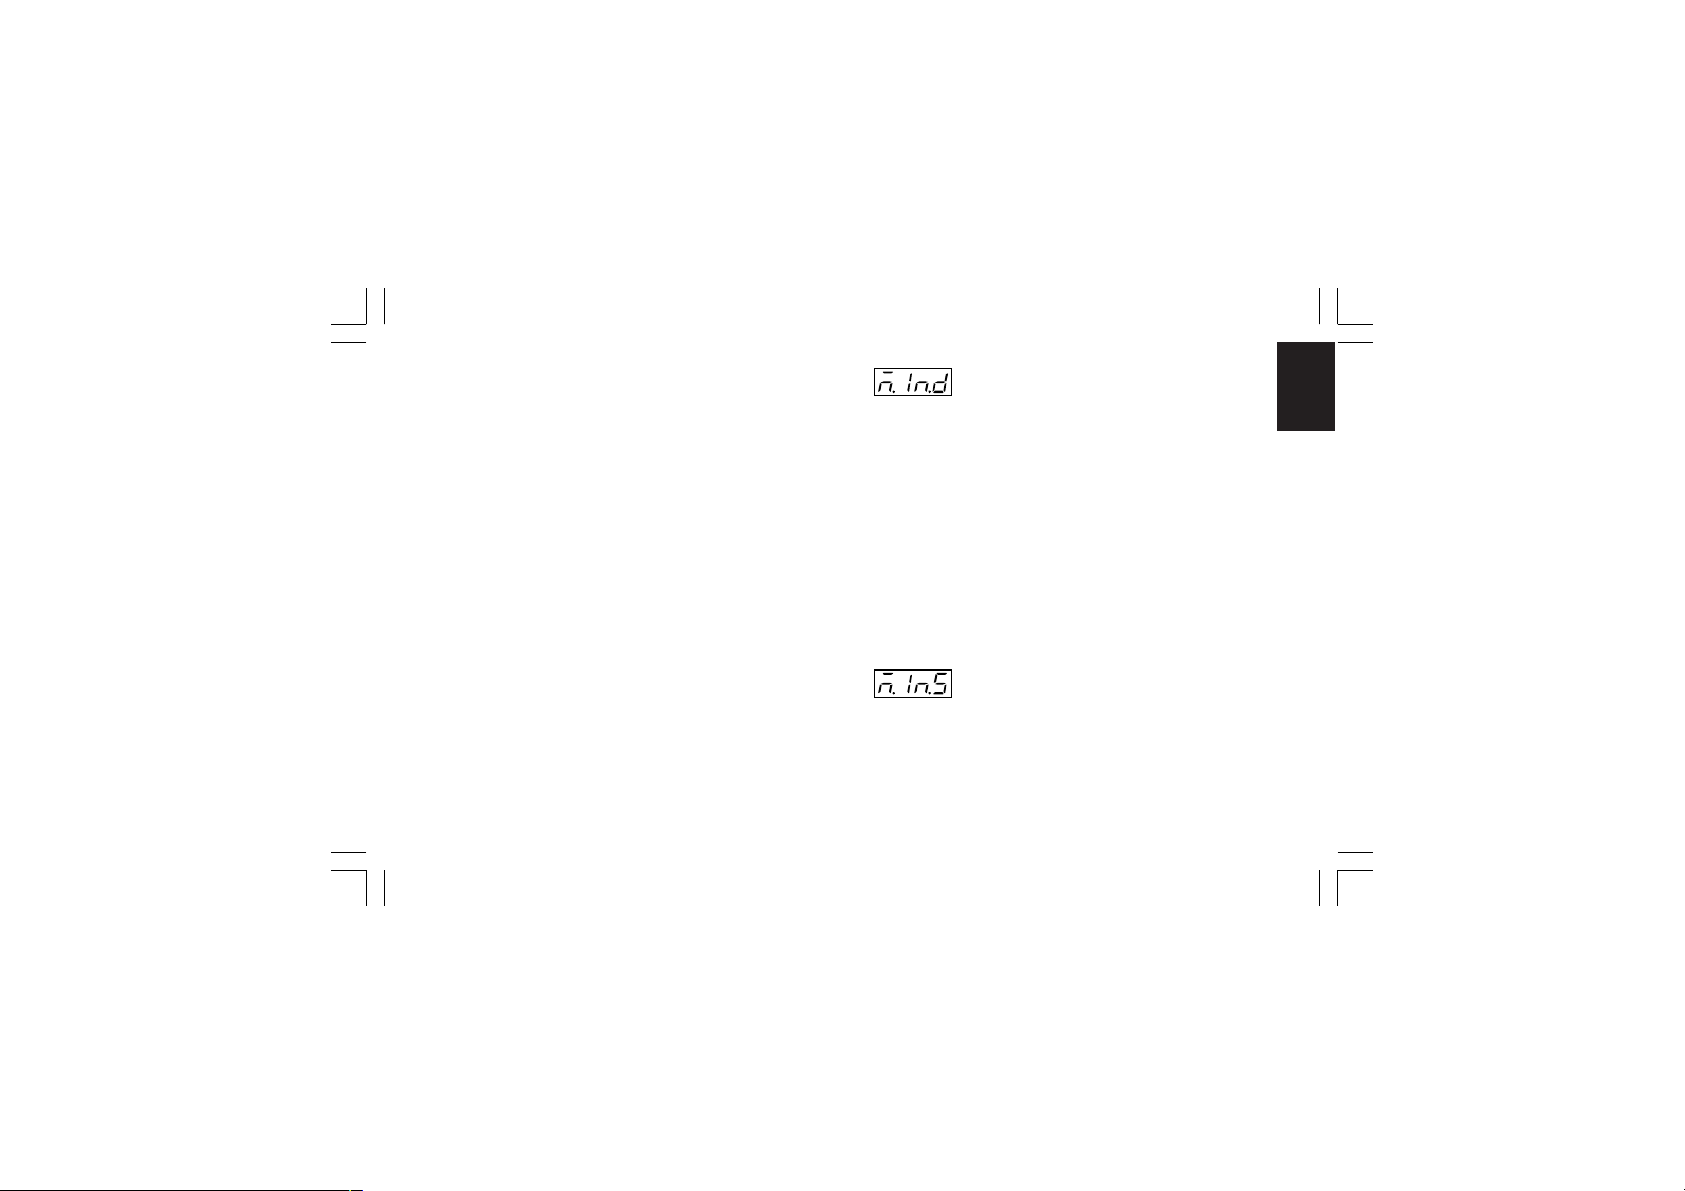
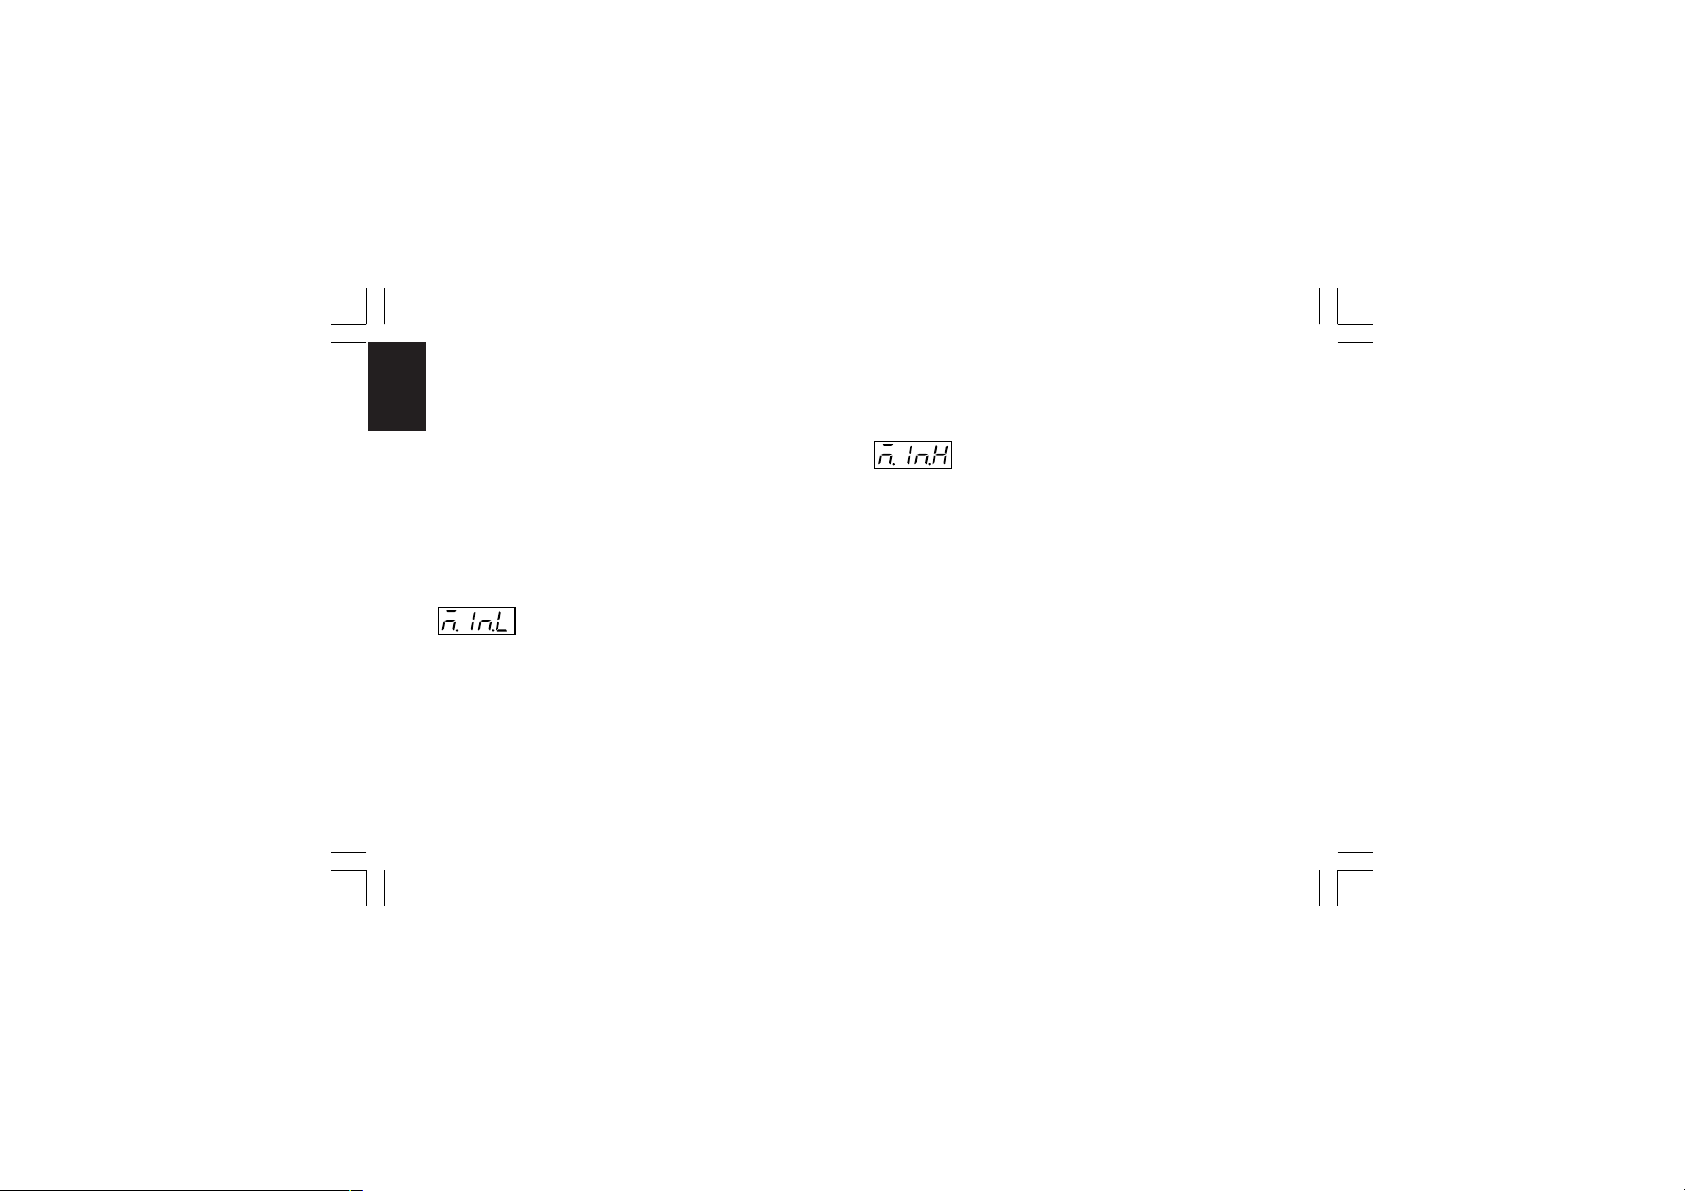
- the "ñ.In.L" [C.d05], "SS.th" [C.I09] and "brG.L" [C.I03]
parameters to the new initial scale value,
- the "ñ.In.H" [C.d06] and "brG.H" [C.I04] parameter to the
new final scale value and
- the "ñ.In.d" [C.d03] parameter to "no decimal figure".
Xkc-1-C0.P65 5/29/02, 11:59 AM33
- Decimal point position - [C.d03]
Ranges:
----. = no decimal figure
---.- = one decimal figure
--.-- = two decimal figures
-.--- = three decimal figures
NOTES:
1) For main input type 1 to 6, 15 and 30 only the "no decimal
figure" and "one decimal figure" are selectable, the input
range is limited within -199.9 and 999.9 and it acts as an input
type changement.
2) For main input type 7 to 14 and 16 to 29 this parameter is not
available.
3) For linear input types (from 31 to 38) all positions are
available.
Ranges: dIS = square root extraction disabled
33
- Square root extraction for main input- [C.d04]
Enb = square root extraction enabled
CnF. 1
Page 38
NOTES:
1) This parameter is available only for main input type 31 to 38.
2) When the square root extraction is enabled the "ñ.In.L" (read-
CnF. 1
out - initial scale value [C.d05]), "ñ.In.H" (read-out - full scale
value [C.d06]), "brG.L" (bargraph - initial scale value [C.I03]),
"brG.H" (bargraph - full scale value [C.I04]) and "SS.th"
(threshold to enable the soft start [C.I09]) parameter values
must be positive or equal to zero.
Enabling the square root extraction the instrument verify the
actual value of the "ñ.In.L", "ñ.In.H", "brG.L", "brG.H" and
"SS.th" parameters and force to zero the eventual negative
values.
- Read-out- initial scale value - [C.d05]
Ranges: - from -1999 to 9999 for linear input (Input range 31 to
38),
- from 0 to 9999 for linear input with square root
extraction,
- from initial range value to "ñ.In.H" (read-out- full scale
value C.d06]) for TC/RTD input
NOTE: Changing the value of this parameter, the "brG.L"
(bargraph - initial scale value [C.I03]) and "rL" (set point low limit
[r.E12]) parameters will be realigned to it.
Xkc-1-C0.P65 5/29/02, 11:59 AM34
If a linear input is selected, also the “SS.th” (threshold for soft
start [C.I09]) will be realigned to it.
- Read-out- full scale value - [C.d06]
Ranges: - from -1999 to 9999 for linear input (Input range 31 to
38),
- from 0 to 9999 for linear input with square root
extraction,
- from "ñ.In.L" (read-out- initial scale value [C.d05]) to
full range value for TC/RTD input.
NOTES:
1) Changing the value of this parameter, the "brG.H" (bargraph full scale value [C.I04]) and "rH" (set point high limit [r.E13])
parameters will be realigned to it.
2) The programmed input span, in absolute value, must be
greater than:
300 °C or 550 °F for TC inputs
100°C or 200 °F for RTD inputs
100 digits for linear inputs.
34
Page 39
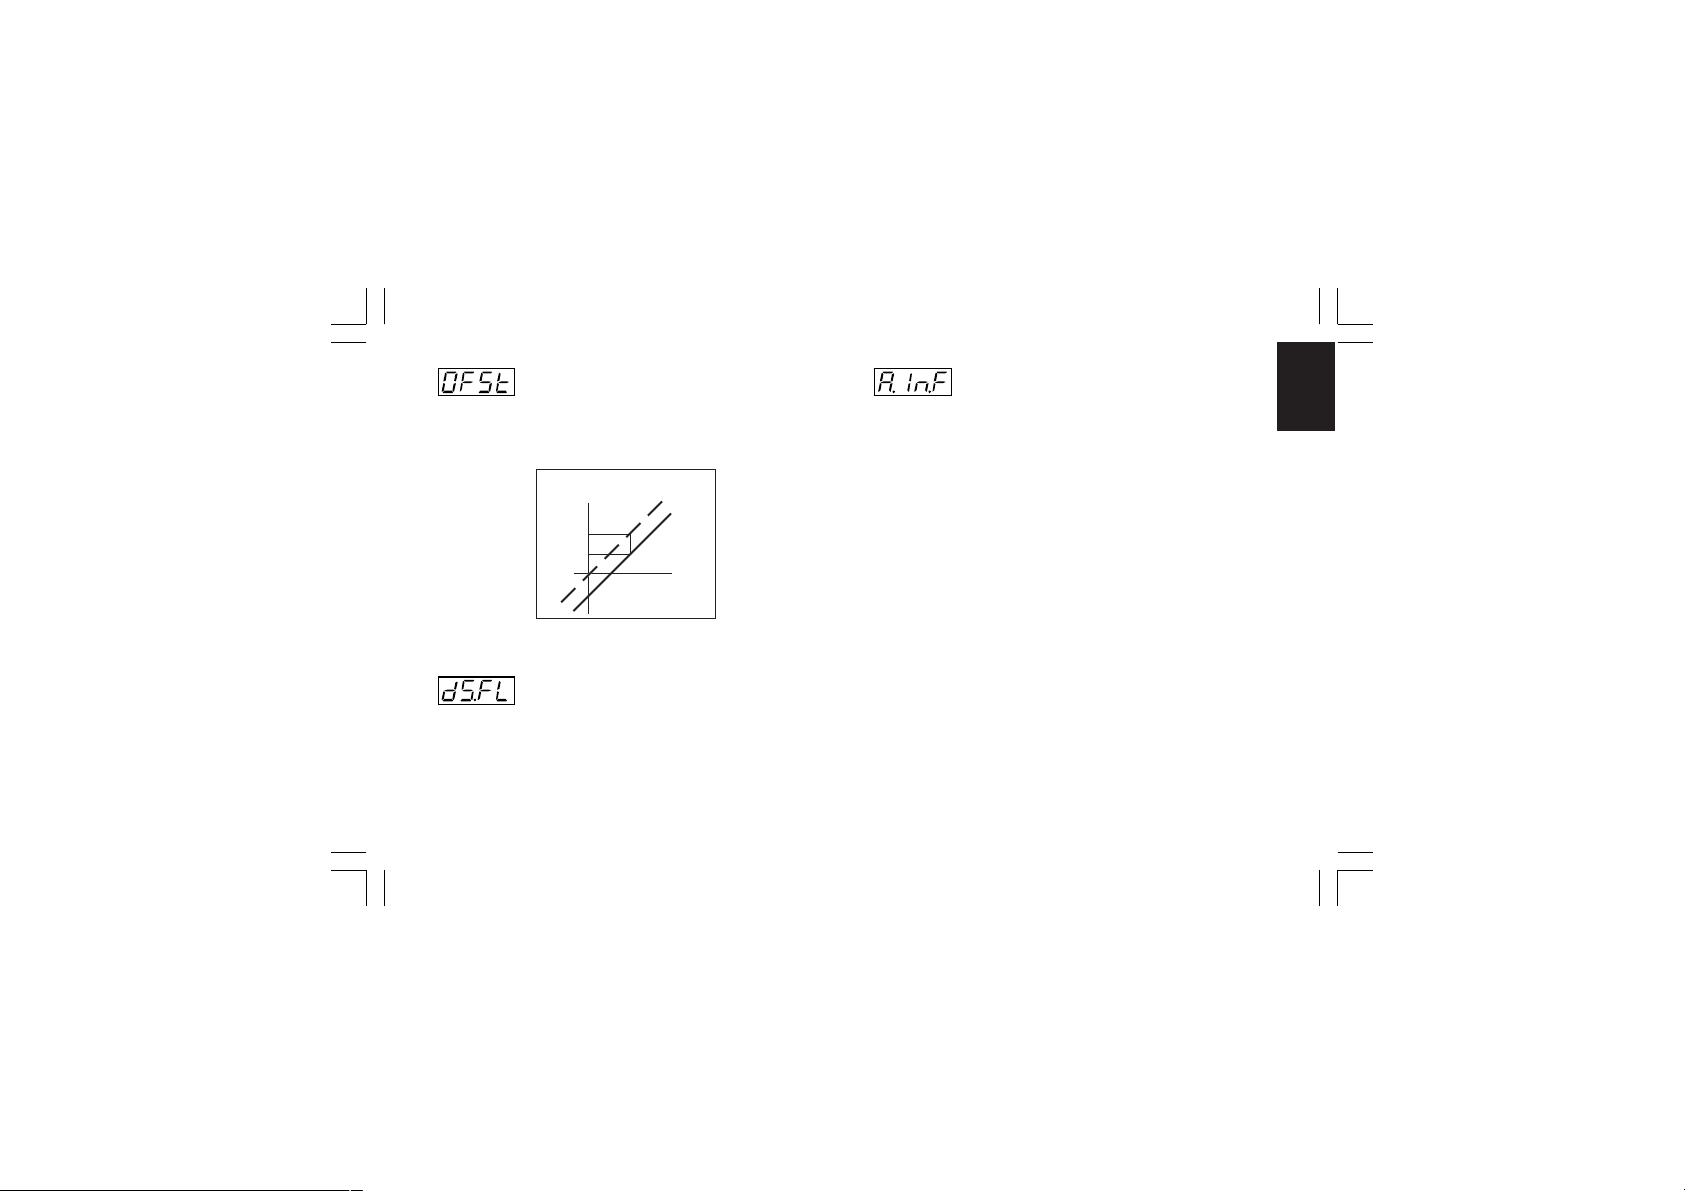
- Offset on the main input - [C.d07]
Ranges: from -500 to 500.
NOTE: the decimal point will be automatically positioned as
selected for the main input.
Read-out
OFSt
Real curve
Adjusted
curve
Input
- Filter on the displayed value - [C.d08]
Ranges: from 0 (no filter) to 8 seconds.
NOTE: this is a first order digital filter applied to the read-out of
the main input.
Xkc-1-C0.P65 5/29/02, 11:59 AM35
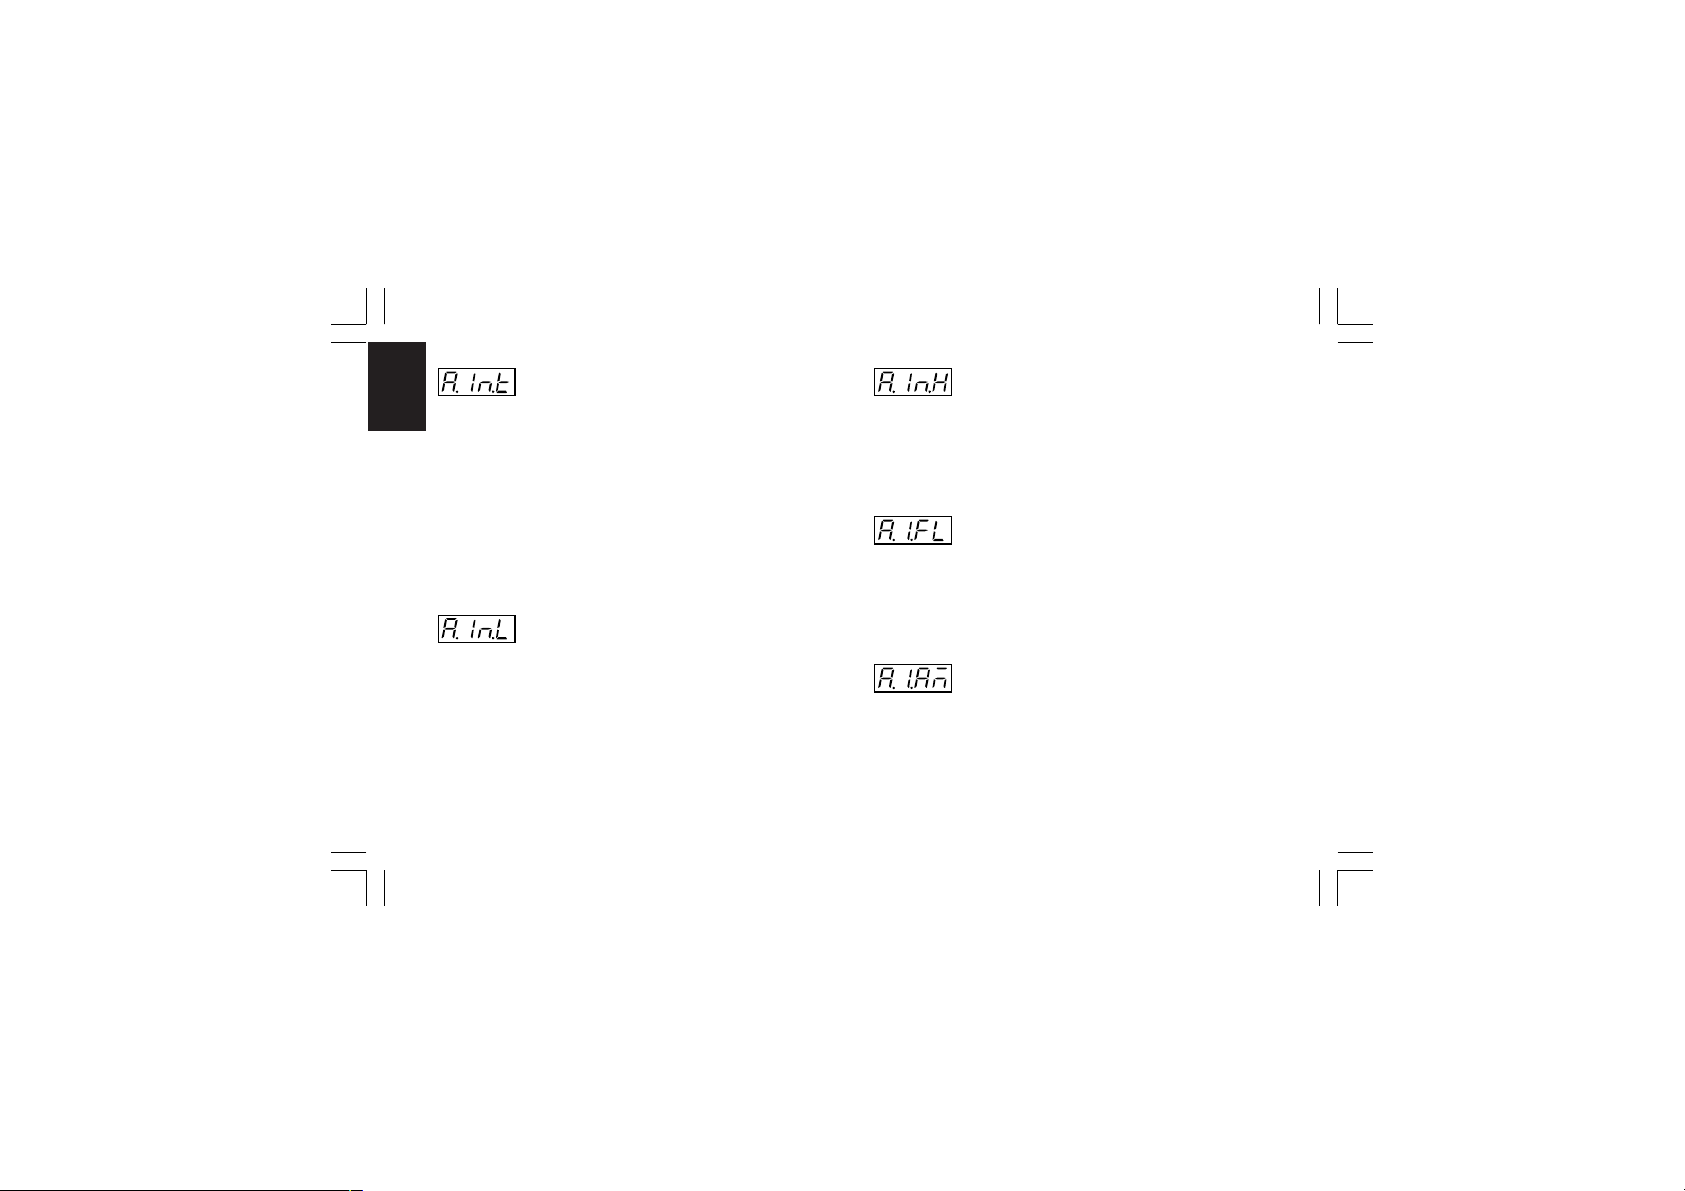
- Auxiliary input function - [C.d09]
Range: nonE = Input not used
rSP = Input used as remote set point input
bIAS = Input used as bias for local set point
NOTES:
1) When auxiliary input option is not mounted the middle display
will show “no.Pr” (not present).
2) The parameter “L.r.O.ñ” [C.d16] will be forced to “n.ALG” if
“A.In.F” [C.d09]= “bIAS” and “A.I.Añ” [C.d14]= “Cnd.A”.
3) When "bIAS" is selected, the instrument uses as operative set
point the sum of the local set point with the value measured
by the auxiliary input scaled by "A.In.L" [C.D11] and "A.In.H"
[C.d12] parameters.
35
CnF. 1
Page 40
- Auxiliary input type - [C.d10]
This parameter will be skipped when the auxiliary input option is
CnF. 1
not mounted or "A.In.F" (auxiliary input function [C.d09]) is equal
to "nonE".
Range: 0-20 = 0-20 mA
4-20 = 4-20 mA
0- 5 = 0- 5 V
1- 5 = 1- 5 V
0-10 = 0-10 V
2-10 = 2-10 V
- Initial scale read-out of the auxiliary input
- [C.d11]
This parameter is available only when auxiliary input is
configured
Range: from -1999 to 9999
NOTE: the decimal point will be automatically positioned as
selected for the main input.
Xkc-1-C0.P65 5/29/02, 11:59 AM36
- Full scale read-out of the auxiliary input
- [C.d12]
This parameter is available only when auxiliary input is
configured
Range: from -1999 to 9999
NOTE: the decimal point will be automatically positioned as
selected for the main input.
- Filter on auxiliary input - [C.d13]
This parameter is available only when auxiliary input is
configured
Ranges: from 0 (no filter) to 8 seconds.
NOTE: this is a first order digital filter applied to the measured
value made by the auxiliary input.
- Auxiliary input activation mode - [C.d14]
This parameter is available only when auxiliary input is
configured
Range: norñ = The auxiliary input activation is controlled by
external contact, front key or serial link
36
Page 41
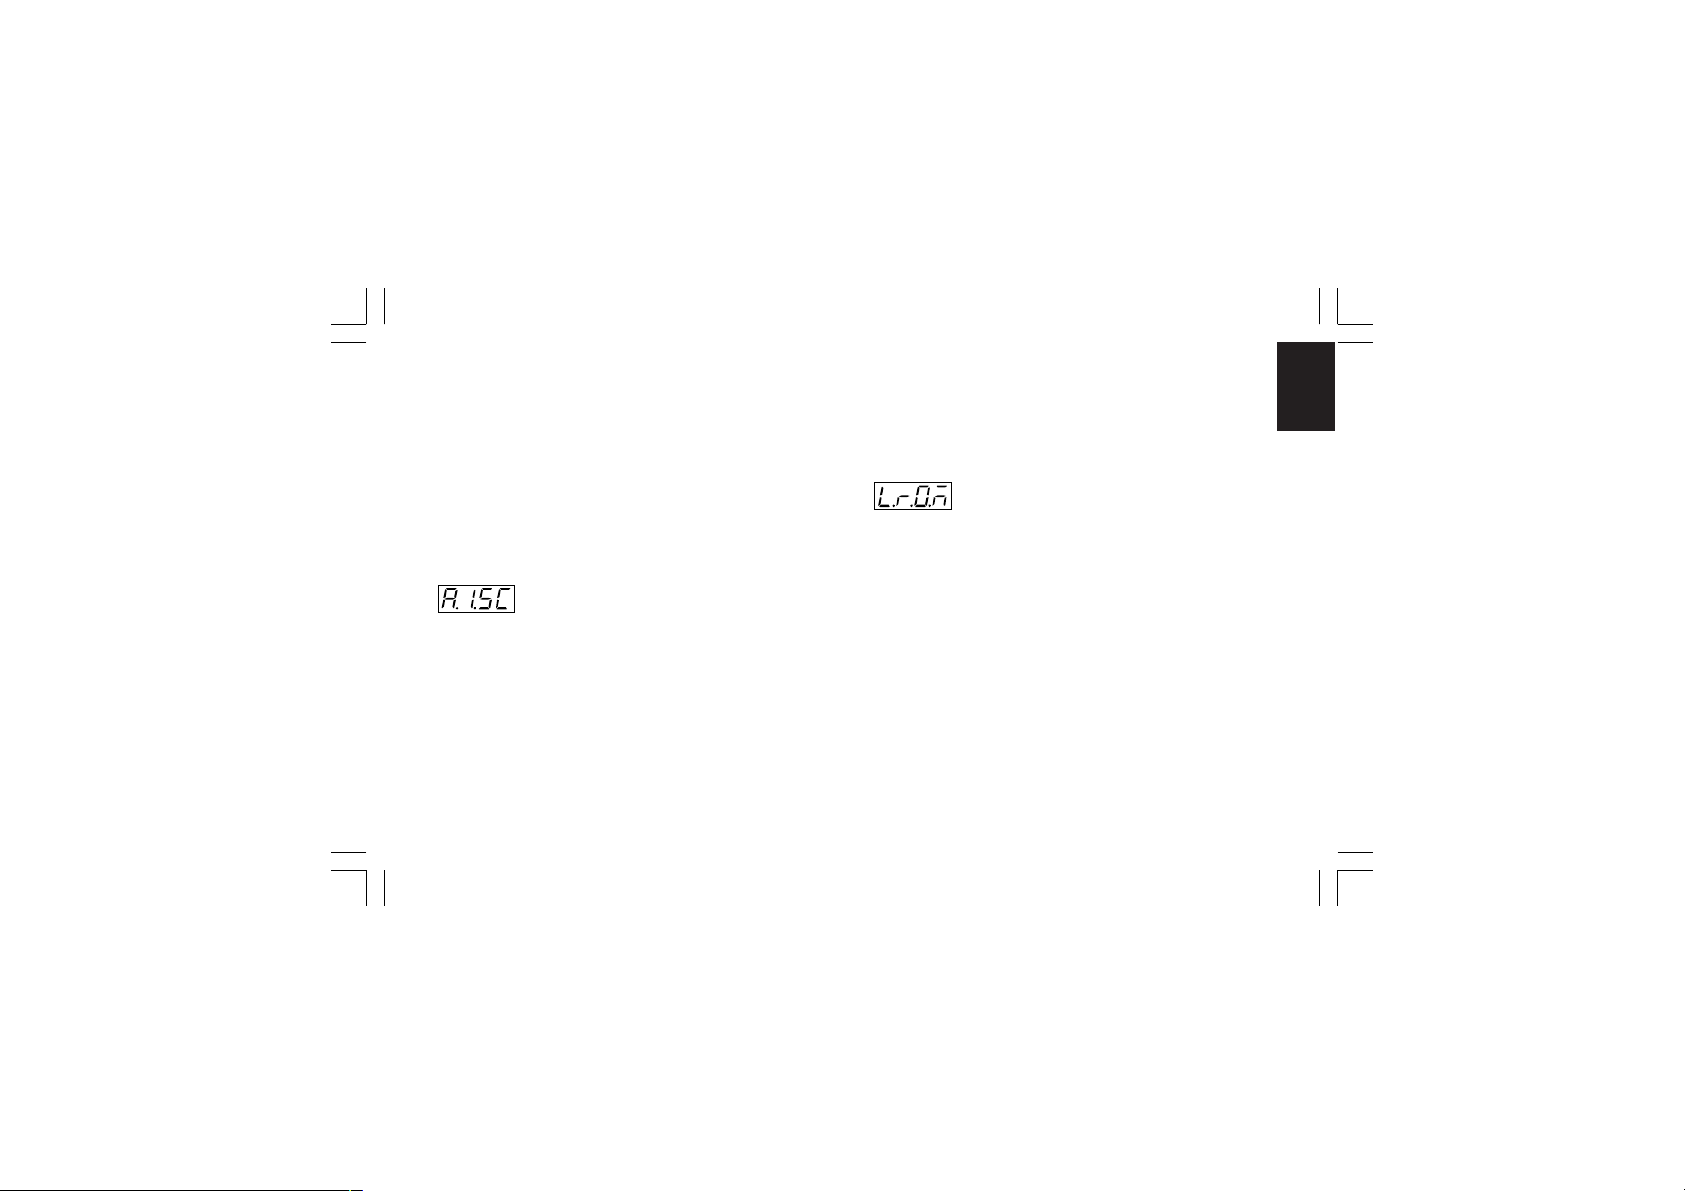
Cnd.A= The auxiliary input activation is controlled by its
status (The device works with local set point
when auxiliary input is out of range, while it
works with remote set point (or bias) when it is
within range)
NOTE: The parameter “L.r.O.ñ” (local/remote set point operative
mode [C.d16]) will be forced to “n.ALG” if “A.In.F” (auxiliary input
function [C.d09]) is equal to “bIAS” and “A.I.Añ” (auxiliary input
activation mode [C.d14]) is equal to “Cnd.A”.
- Auxiliary input safety condition - [C.d15]
This parameter is available only when auxiliary input is
configured and "A.i.Añ" [C.d14] is equal to "norñ".
Range: nonE = when the auxiliary input is out of range, the
instrument operates as in presence of the min
or max auxiliary input value.
Cnd.A = when the auxiliary input is out of range, the
control output goes to safety value “SF.UL”
(output safety value [C.G08]).
If servomotor open loop control drive is
configured the “Safety value” "SF.UL" [C.G08]
has no effect and the instrument operates in
Xkc-1-C0.P65 5/29/02, 11:59 AM37
accordance with “SF.Cn” (Output safety
condition [C.G07]) parameter setting.
NOTE: The “SF.Cn” (Output safety condition” [C.G07]) has the
priority on “A.I.Sc” (auxiliary input safety condition [C.d15]).
- Local/remote set point operative mode
- [C.d16]
This parameter is available only when auxiliary input is
configured
Range: ALG = when the transfer from remote to local set point
is performed, the local set point value will be
aligned to last remote set point value.
n.ALG = when the transfer from remote to local set point
is performed, the local set point value will not
be changed (The programmed ramps Grd1
[r.E14] and Grd2 [r.E15] may be activated).
NOTES:
1) The selected local set point will be changed even if it is
software protected.
2) The parameter is forced to “n.ALG” if “A.In.F” (auxiliary input
function [C.d09]) is equal to “bIAS” and “A.I.Añ” (auxiliary
input activation mode [C.d14]) is equal to “Cnd.A”
37
CnF. 1
Page 42
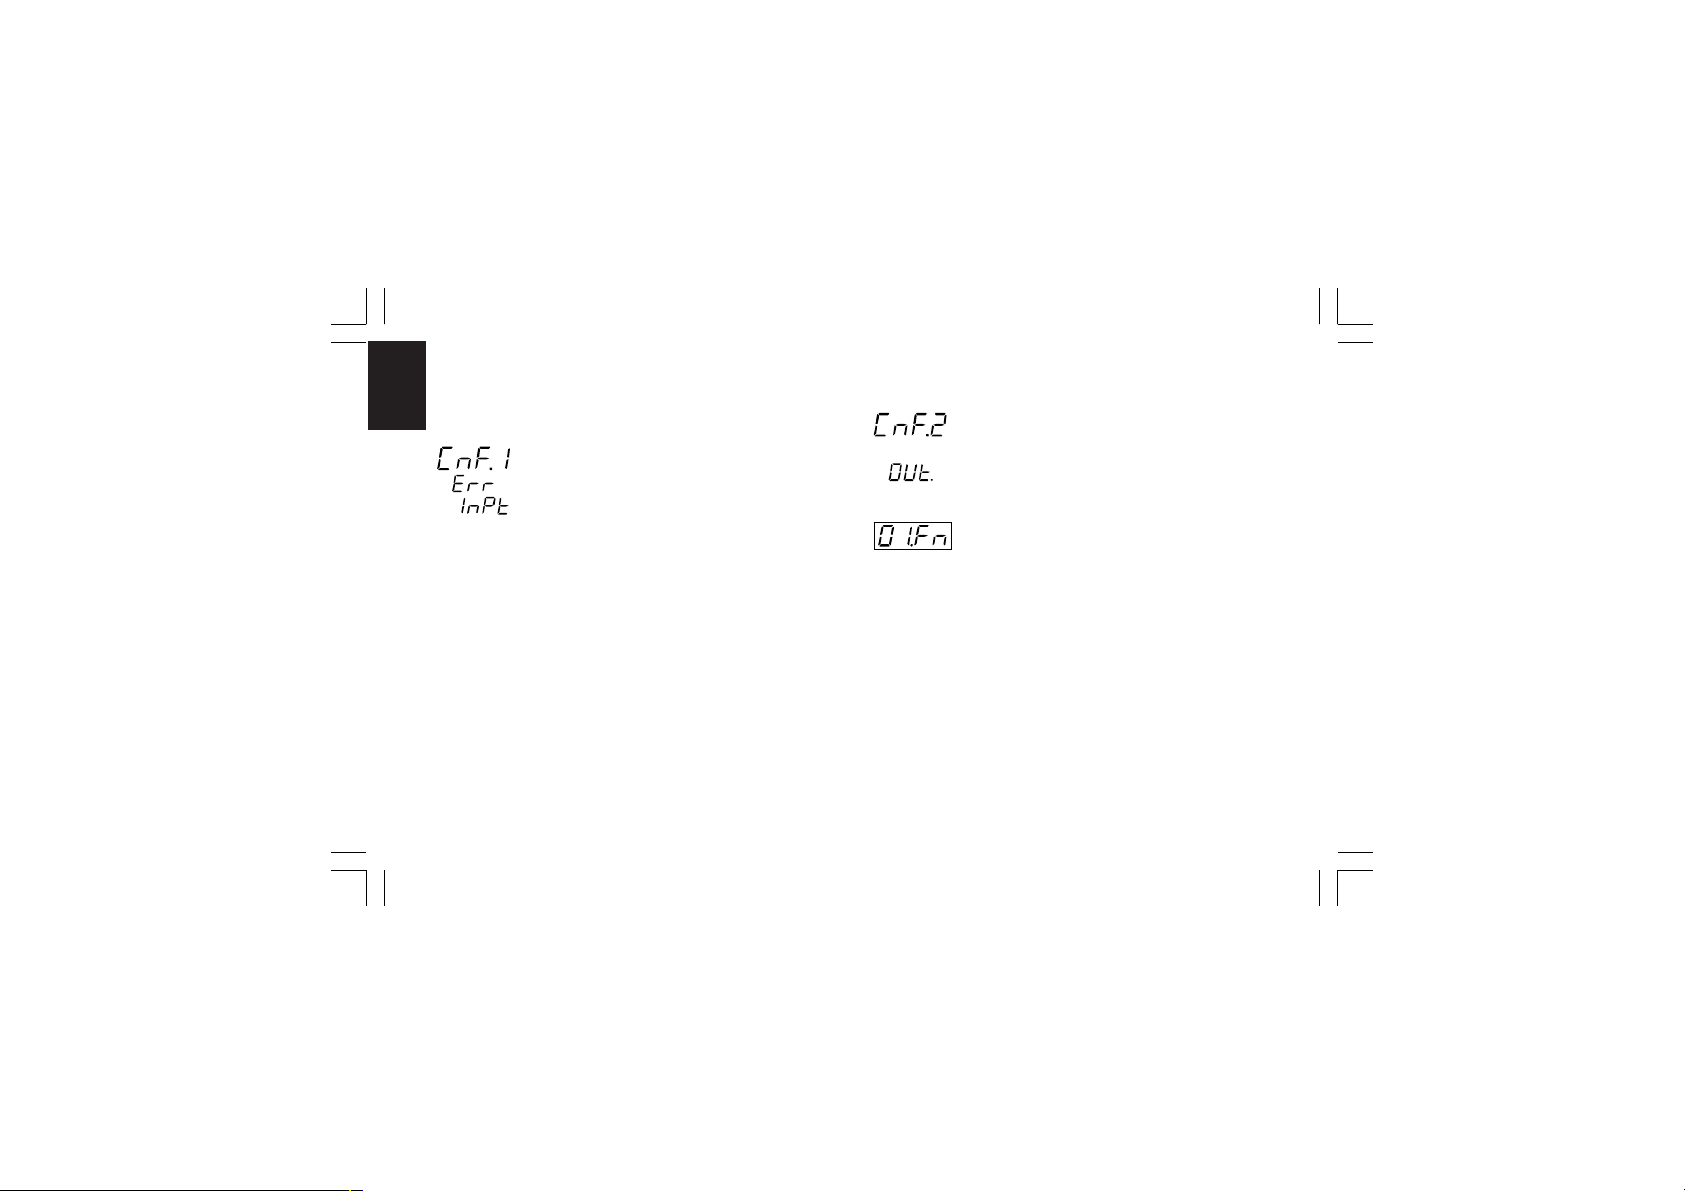
General note on configuration group 1
Exiting from the configuration group 1 the instrument verifies
automatically the programmed span for the linear input.
CnF. 2
If it is wrong, the device will show:
Xkc-1-C0.P65 5/29/02, 11:59 AM38
CONFIGURATION GROUP 2 [C.Exx]
OUTPUTS CONFIGURATION
- OUT 1 function - [C.E01]
Range: nonE = Output not used
ñAin = Time proportional main control output
SECn = Time proportional secondary control output
ALr.1 = Alarm 1 output
Eun.1 = Event 1 output
38
Page 43
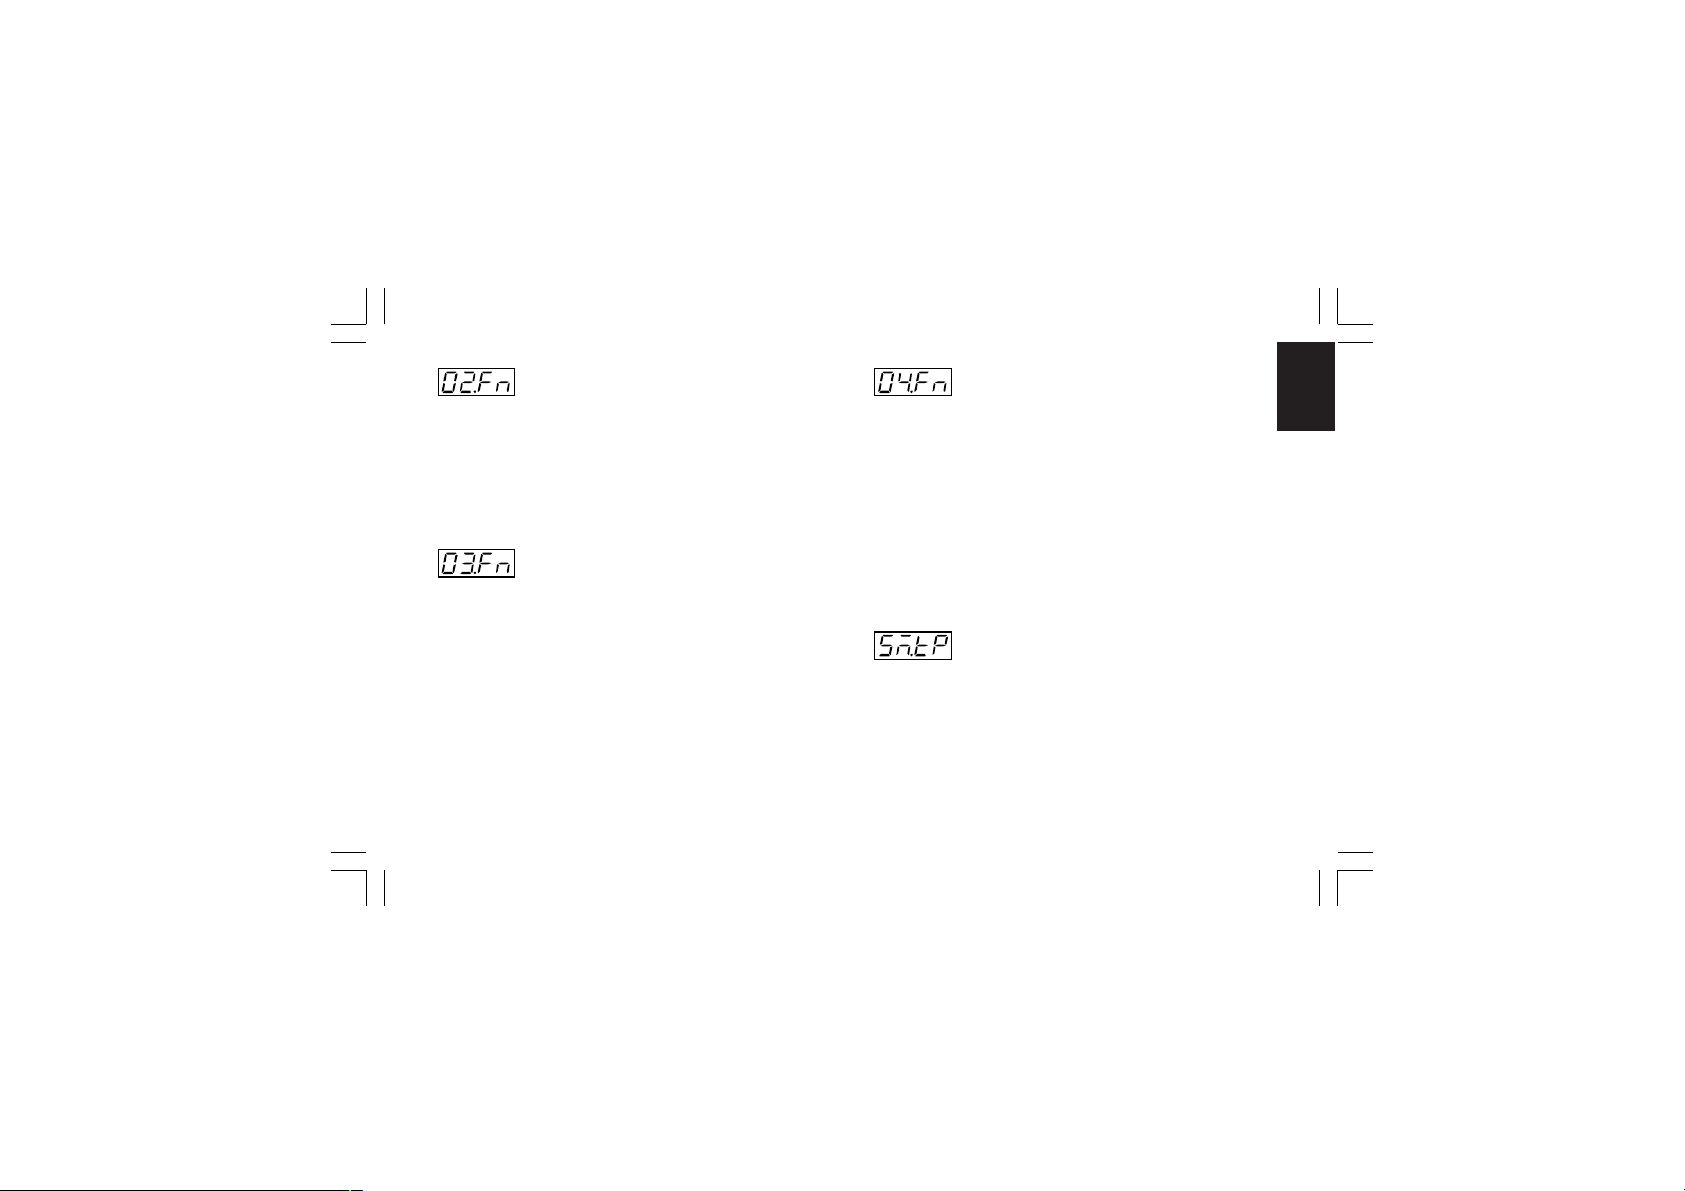
- OUT 2 function - [C.E02]
Range: nonE = Output not used
ñAin = Time proportional main control output
SECn = Time proportional secondary control output
ALr.2 = Alarm 2 output
Eun.2 = Event 2 output
- OUT 3 function - [C.E03]
When the option is not mounted the middle display will show
“no.Pr” (not present).
Range: nonE = Output not used
ñAin = Time proportional main control output
SECn = Time proportional secondary control output
ALr.3 = Alarm 3 output
Eun.3 = Event 3 output
ñC.Sñ = Servomotor control drive as main control output
SC.Sñ = Servomotor control drive as secondary control
output
Xkc-1-C0.P65 5/29/02, 11:59 AM39
- OUT 4 function - [C.E04]
Range: nonE = Output not used
ñAin = Time proportional main control output
SECn = Time proportional secondary control output
ALr.4 = Alarm 4 output
Eun.4 = Event 4 output
NOTES:
1) When option is not mounted the middle display will show
“no.Pr” (not present).
2) When servomotor control drive is hardware selected (see
"Output 3 and 4 selection" at pag. 20), the OUT 4 can be
used only as servomotor drive.
- Servomotor type - [C.E05]
This parameter will be available only when servomotor control
drive is configured (“CnF.2 - O3.Fn” [C.E03]= “ñC.Sñ” or
“SC.Sñ”).
Range: CLSd = Close loop type
NOTE: this selection is available only if
feedback circuitry is mounted and selected.
OPEn = Open loop type
39
CnF. 2
Page 44
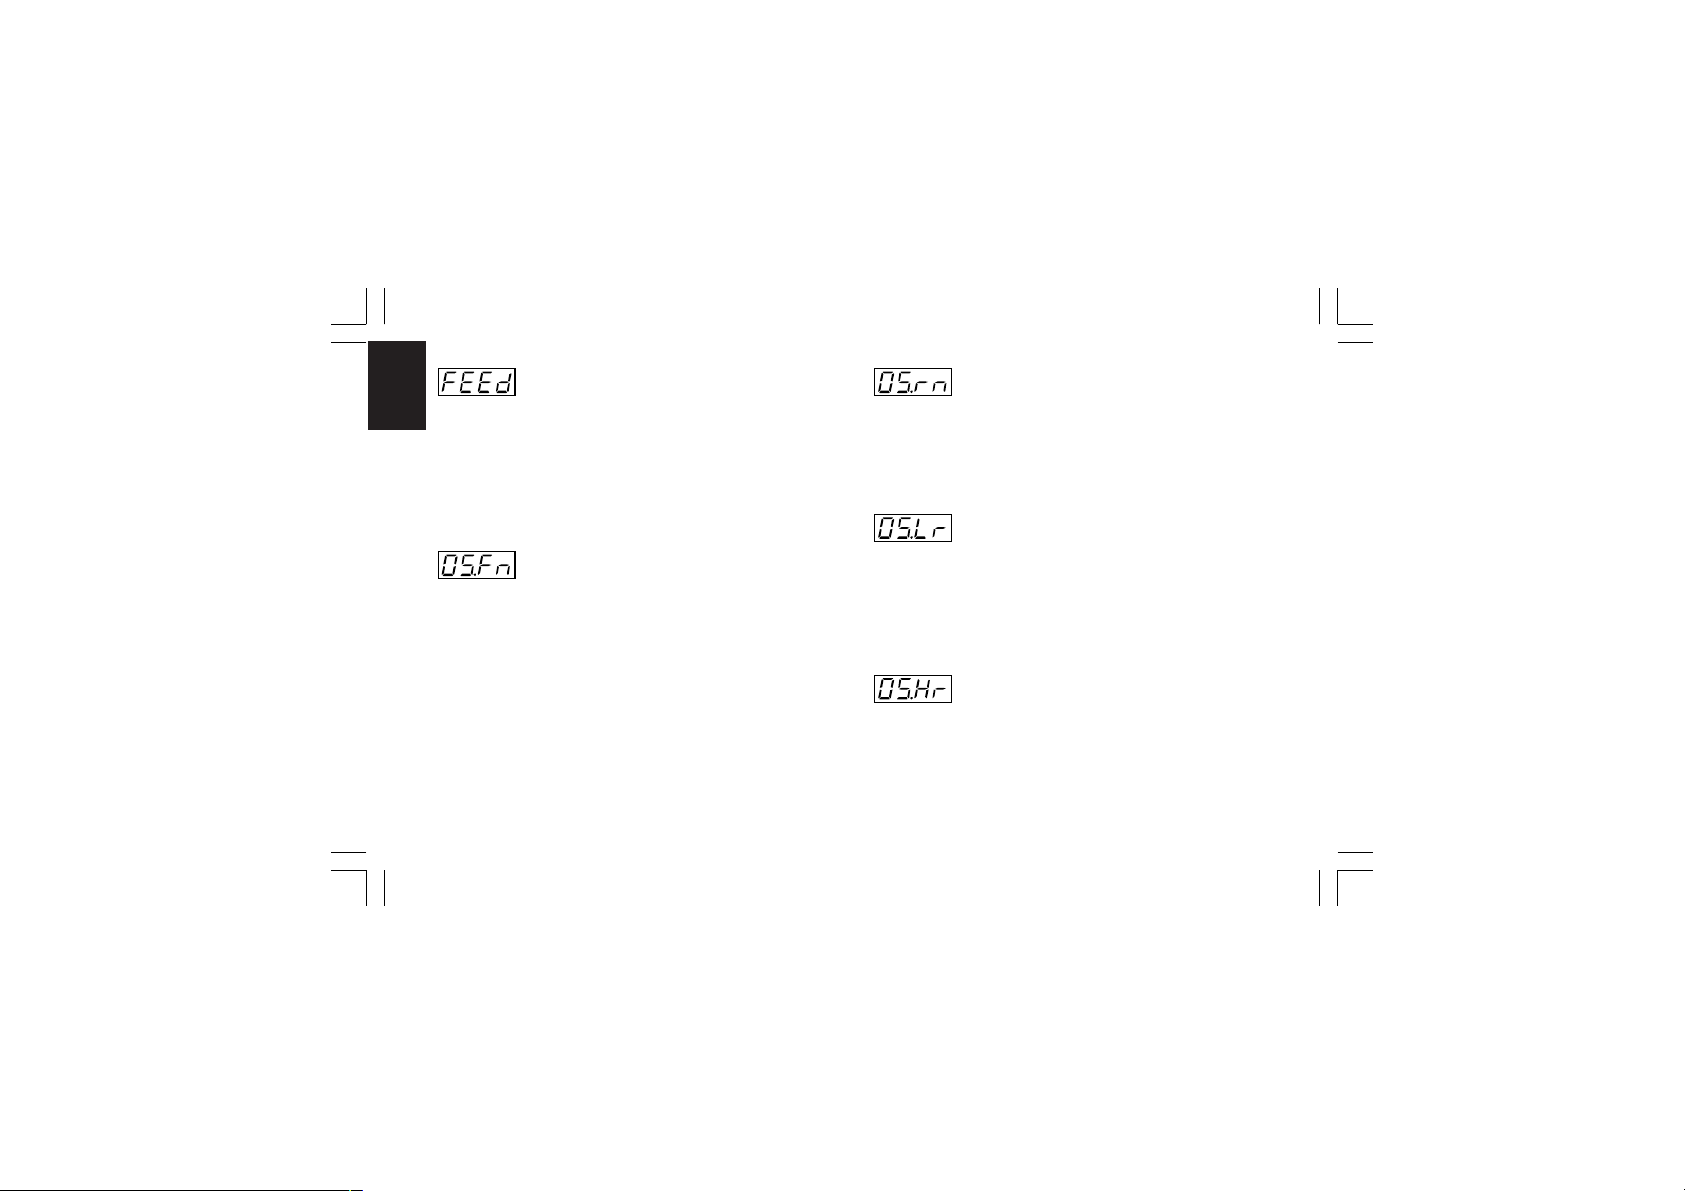
- Valve position indication - [C.E06]
This parameter will be displayed only when open loop
CnF. 2
servomotor control drive output is confi-gured.
Range: Fb = The valve position is measured and displayed
no.Fb = The valve position is not measured
NOTE: If the feedback option is not mounted, this parameter will
be forced to “no.Fb” (no feedback).
- OUT 5 function - [C.E07]
Range: nonE = Output not used
ñAin = Main control output (linear)
SECn = Secondary control output (linear)
PV.rt = Process variable retransmission
SP.rt = Operative set point retransmission
NOTE: When the option circuitry is not mounted the middle
display will show “no.Pr” (not present).
Xkc-1-C0.P65 5/29/02, 11:59 AM40
- OUT 5 range - [C.E08]
This parameter will be available only when Out 5 is configured
("O5.Fn" [C.E07] different from "nonE")
Range: 0-20 = 0¸20 mA
4-20 = 4¸20 mA
- OUT 5 retransmission initial scale value
- [C.E09]
This parameter will be available only when Out 5 function
[C.E07] is configured as “PV.rt” or “SP.rt”
Range: From -1999 to 9999
NOTE: Decimal point is positioned as previously selected at
“CnF.1 - ñ.In.d” [C.d03])
- OUT 5 retransmission full scale value
- [C.E10]
This parameter will be available only when Out 5 function
[C.E07] is configured as “PV.rt” or “SP.rt”
Range: From -1999 to 9999
NOTE: Decimal point is positioned as previously selected at
“CnF.1 - ñ.In.d” [C.d03])
40
Page 45
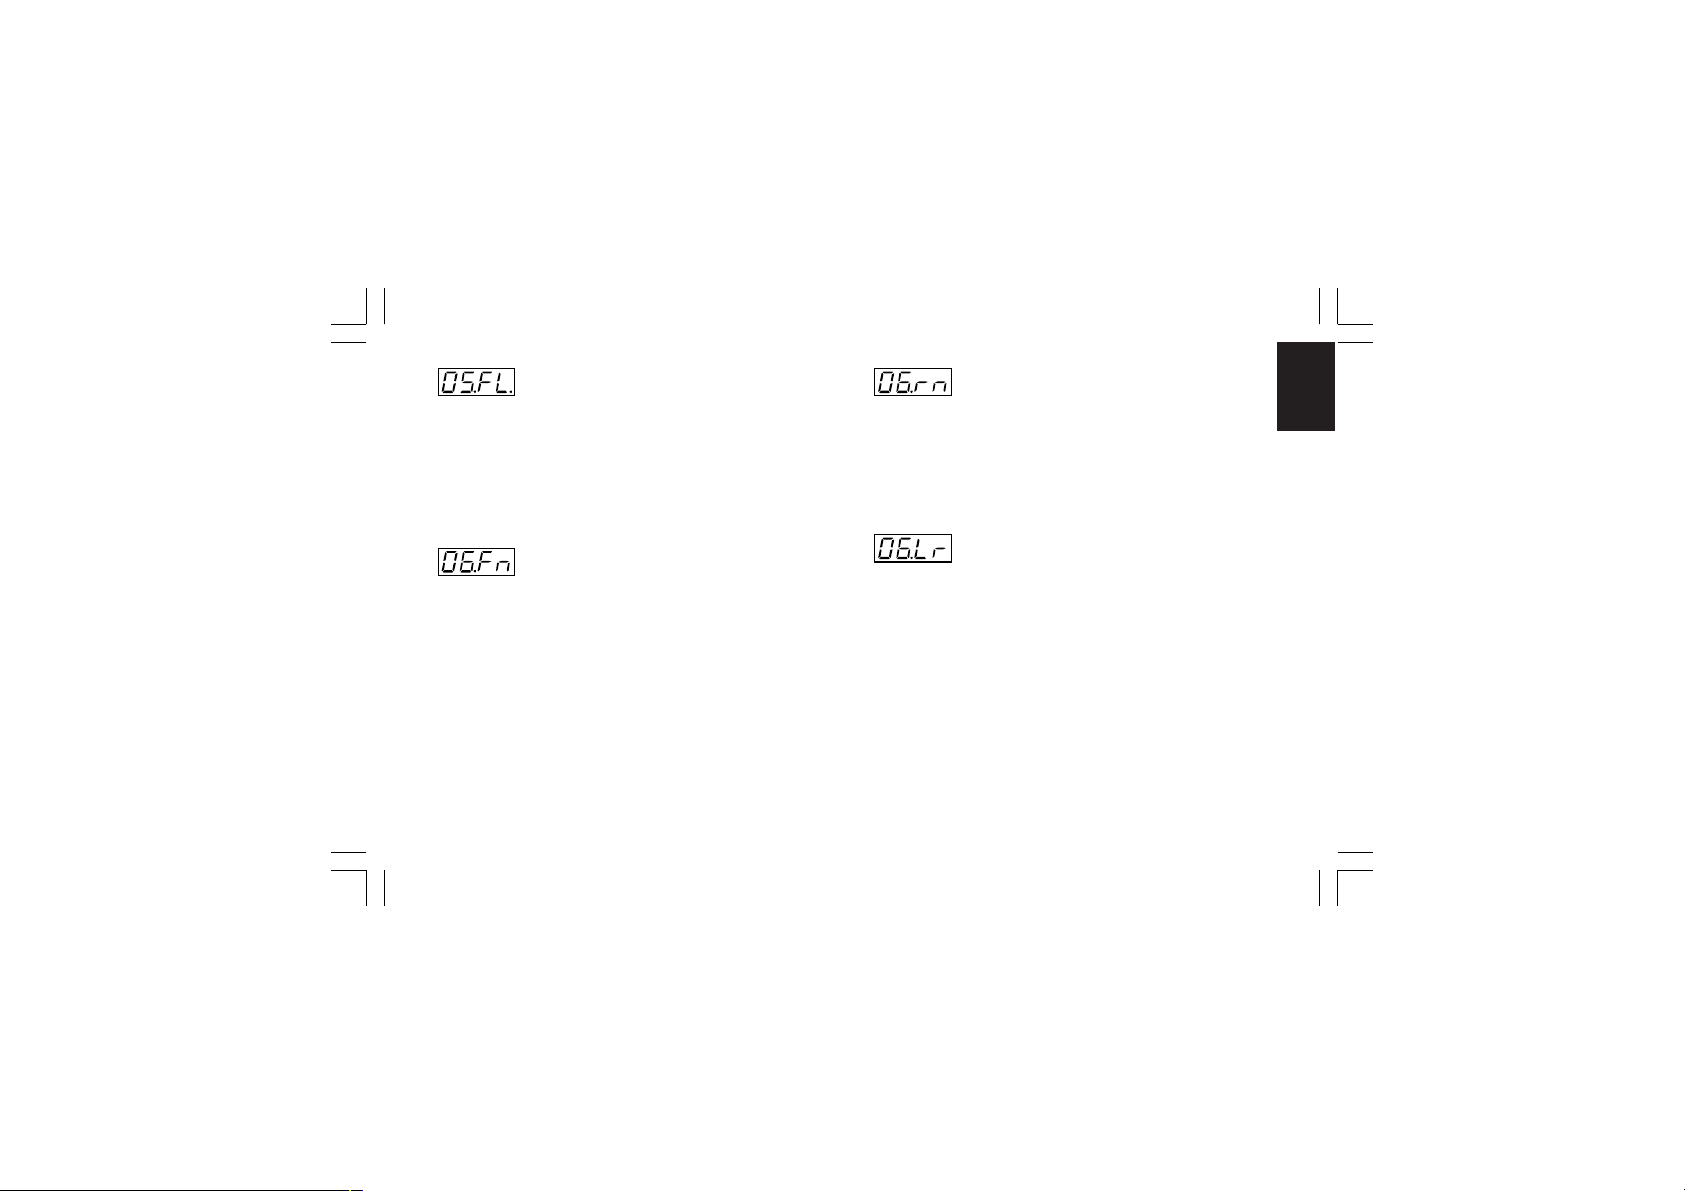
- OUT 5 filter on the retransmitted value
- [C.E11]
This parameter will be available only when OUT 5 is configured
as process variable retransmission ("O5.Fn" [C.E07] is equal to
“PV.rt”).
Range: From 0 (no filter) to 8 seconds
NOTE: this is a first order digital filter applied to the retransmitted output value.
- OUT 6 range - [C.E13]
This parameter will be available only when Out 6 is configured
("O6.Fn" [C.E12] different from "nonE")
Range: 0-20 = 0¸20 mA
4-20 = 4¸20 mA
CnF. 2
- OUT 6 function - [C.E12]
Range: nonE = Output not used
ñAin = Main control output (linear)
SECn = Secondary control output (linear)
PV.rt = Process variable retransmission
SP.rt = Operative set point retransmission
NOTE: When the option circuitry is not mounted the middle
display will show “no.Pr” (not present).
Xkc-1-C0.P65 5/29/02, 11:59 AM41
- OUT 6 retransmission initial scale value
- [C.E14]
This parameter will be available only when Out 6 function
[C.E12] is configured as “PV.rt” or “SP.rt”
Range: From -1999 to 9999
NOTE: Decimal point is positioned as previously selected at
“CnF.1 - ñ.In.d” [C.d03].
41
Page 46
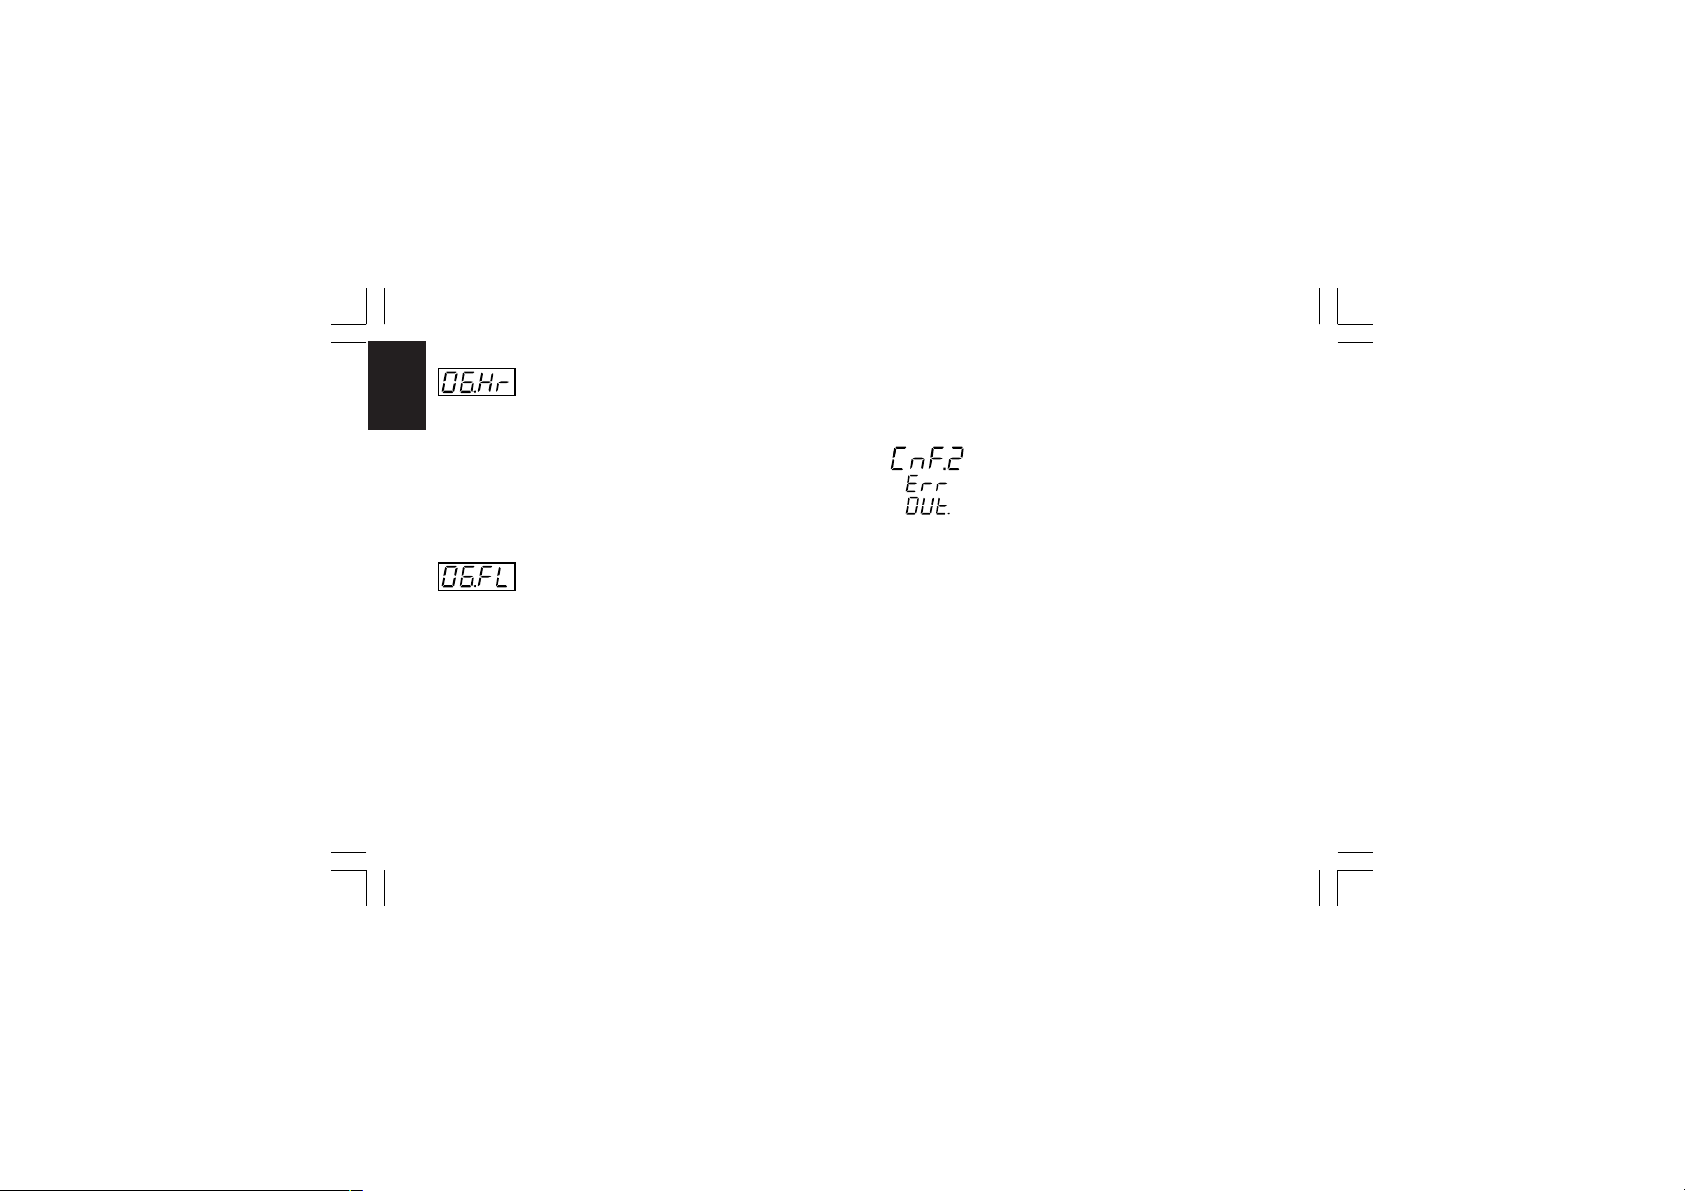
- OUT 6 retransmission full scale value
This parameter will be available only when Out 6 function
CnF. 2
[C.E12] is configured as “PV.rt” or “SP.rt”
- [C.E15]
Range: From -1999 to 9999
NOTE: Decimal point is positioned as previously selected at
“CnF.1 - ñ.In.d” [C.d03])
- OUT 6 filter on the retransmitted value
- [C.E16]
This parameter will be available only when OUT 6 is configured
as process variable retransmission ("O6.Fn" [C.E12] is equal to
“PV.rt”).
Range: From 0 (no filter) to 8 seconds
NOTE: this is a first order digital filter applied to the retransmitted output value.
Xkc-1-C0.P65 5/29/02, 11:59 AM42
General notes on configuration group 2
I) Exiting from the configuration group 2 the instrument verifies
automatically the congruence of all parameters. If a wrong
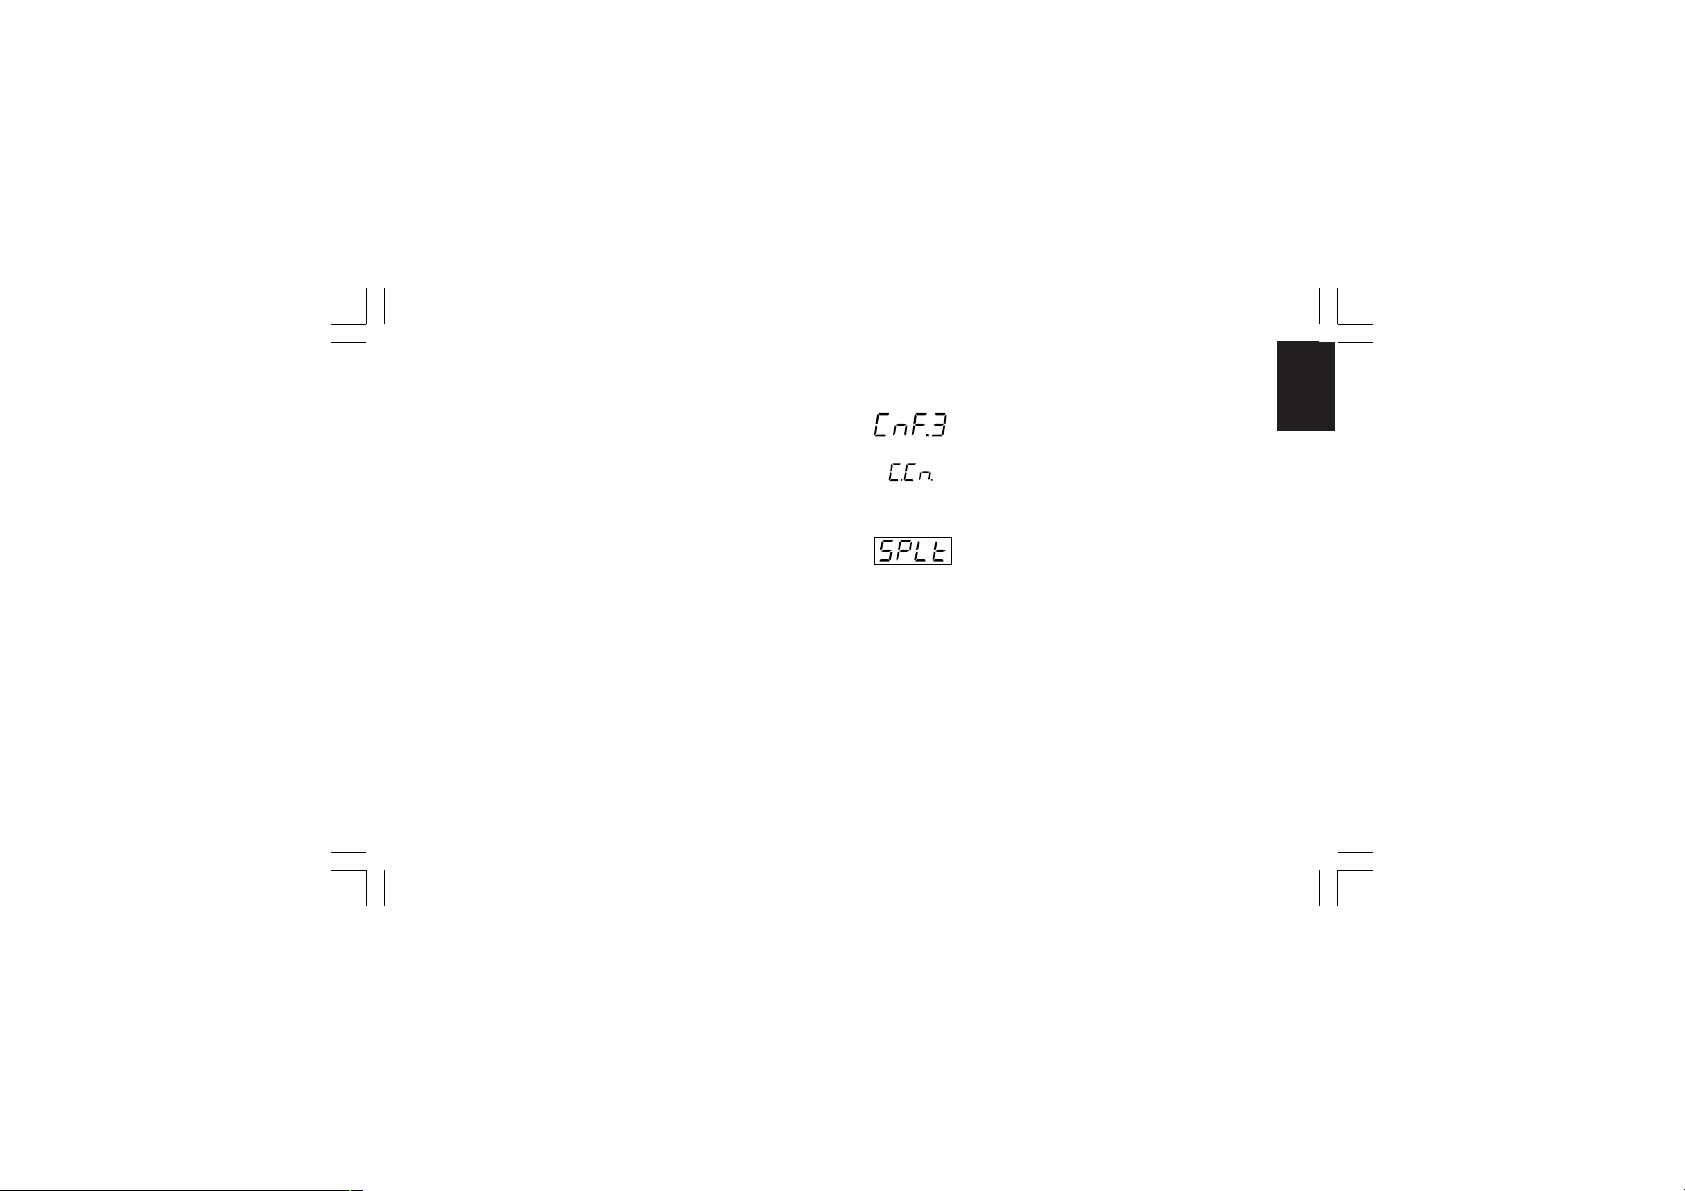
setting is detected, the device will show:
The group 2 parameter passes the congruence test when:
1) Only one of the 6 outputs is configured as main output
(“ñAin”)
2) Only one of the 6 outputs is configured as secondary
output (“SECn”)
3) If only one control output is configured, it should be the
main control output (“ñAin”)
4) The servomotor must be “close loop” type if it is one of two
control outputs.
NOTE: The instrument may be used as an indicator, so that this
test is satisfied even if no output is configured as control output
II) Exiting from the configuration group 2 also the following
actions are automatically performed:
A) The "Añ.UL” parameter ("Output value for auto to manual
transfer" [C.G04]) will be forced to "bumpless" (“buñ”) if:
42
Page 47
1) its value is < 0 and only one control output is configured;
2) servomotor open loop without feedback is configured.
B) The parameter “SF.Cn” ("Condition for output safety value"
[C.G07]) will be forced to "standard" (“Std.”) if it is not
complied with configured control output type
C) The parameter “SF.UL” ("Output safety value" [C.G08]) will
be forced to 0 if only one control output is configured and its
value is < 0.
D) The parameter “Fd.Fn” ("Out failure detection current
measurement" [C.I11]) will be forced to “nonE” if it is
assigned to a control output different from a time
proportional output.
E) The parameter “Fd.Ou” ("Out failure detection output
assignment" [C.I13]) will be forced to “nonE” if it is
assigned to an output configured as control output
F) The parameter “IP” ("Integral pre-load" [r.d05]) will be forced
to 50.0 if only one control output is configured and its value is
< 0
Xkc-1-C0.P65 5/29/02, 11:59 AM43
CONFIGURATION GROUP 3 [C.Fxx]
CONTROL OUTPUT CONFIGURATION
- Split range - [C.F01]
This parameter will be available only when two control outputs
are configured.
Range: dIS = Split range feature is not required
Enb = Split range feature is required
NOTE about the split range.
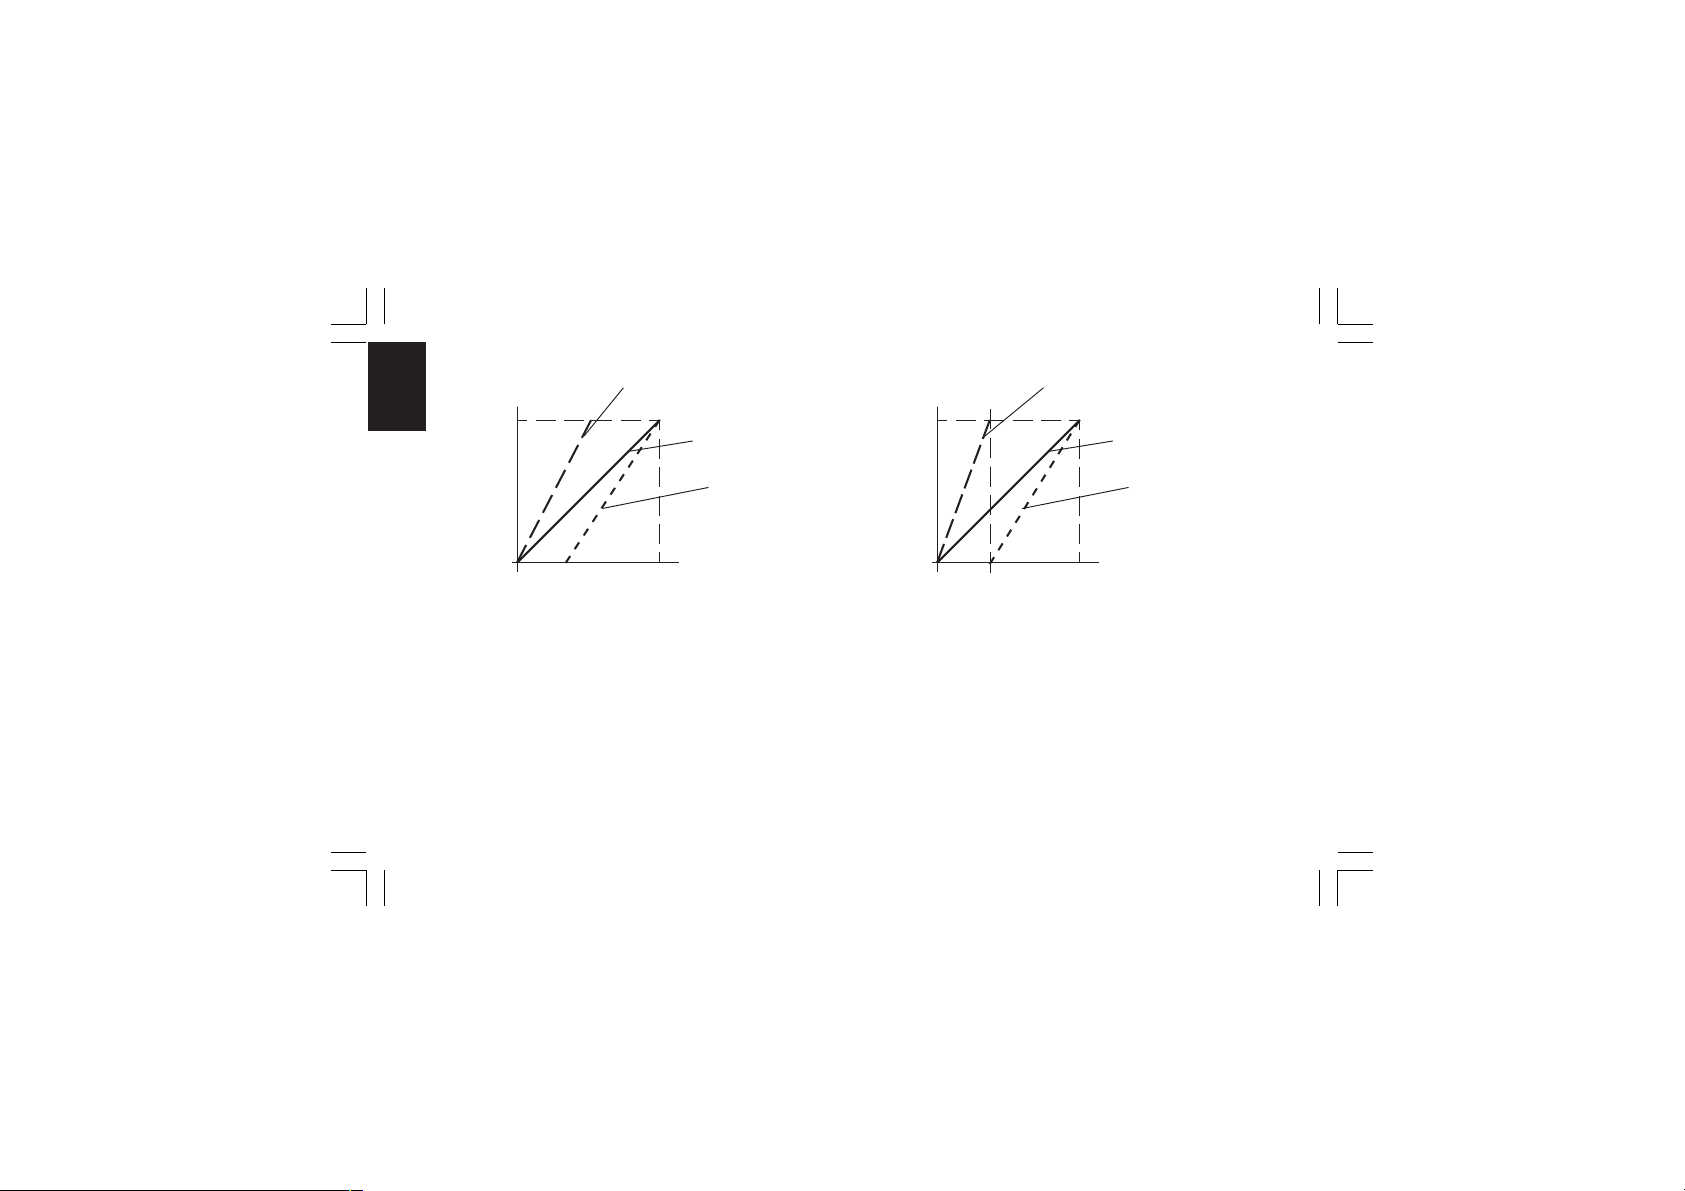
This function allows you to drive by the same control action, two
physical outputs (two actuators) with different bias and gain.
The relation between the Calculated Power Output and the
resulting real outputs are shown below:
43
CnF. 3
CnF. 2
Page 48
CnF. 3
Real PWR
Output
100 %
First split
output (MAIN)
Standard curve
Real PWR
Output
100 %
First split
output (MAIN)
Standard curve
Second split
output
(Secondary)
0 %
100 %
Calculated
PWR Output
ABCD
where:
- for the first split output (MAIN)
Bias 1 = -A
Gain 1 = 100 / (B - A)
- For the second split output (SECONDARY)
Bias 2 = -C
Gain 2 = 100 / (D - C)
FOR EXAMPLE:
Let's suppose that the first split output operates from 0 % to
33.3 % of the calculated output while the second one operates
from 33.3 % to the 100 % of the calculated output.
Xkc-1-C0.P65 5/29/02, 11:59 AM44
0 %
Where: A = 0 %
B = C = 33.3 %
D = 100 %
We will set:
Bias 1 = 0
Gain 1 = 100 / (33.3 - 0) = 3
Bias 2 = - 33.3
Gain 2 = 100 / (100 - 33.3) = 1,5
44
33.3 %
100 %
Second split
output
(Secondary)
Calculated
PWR Output
Page 49
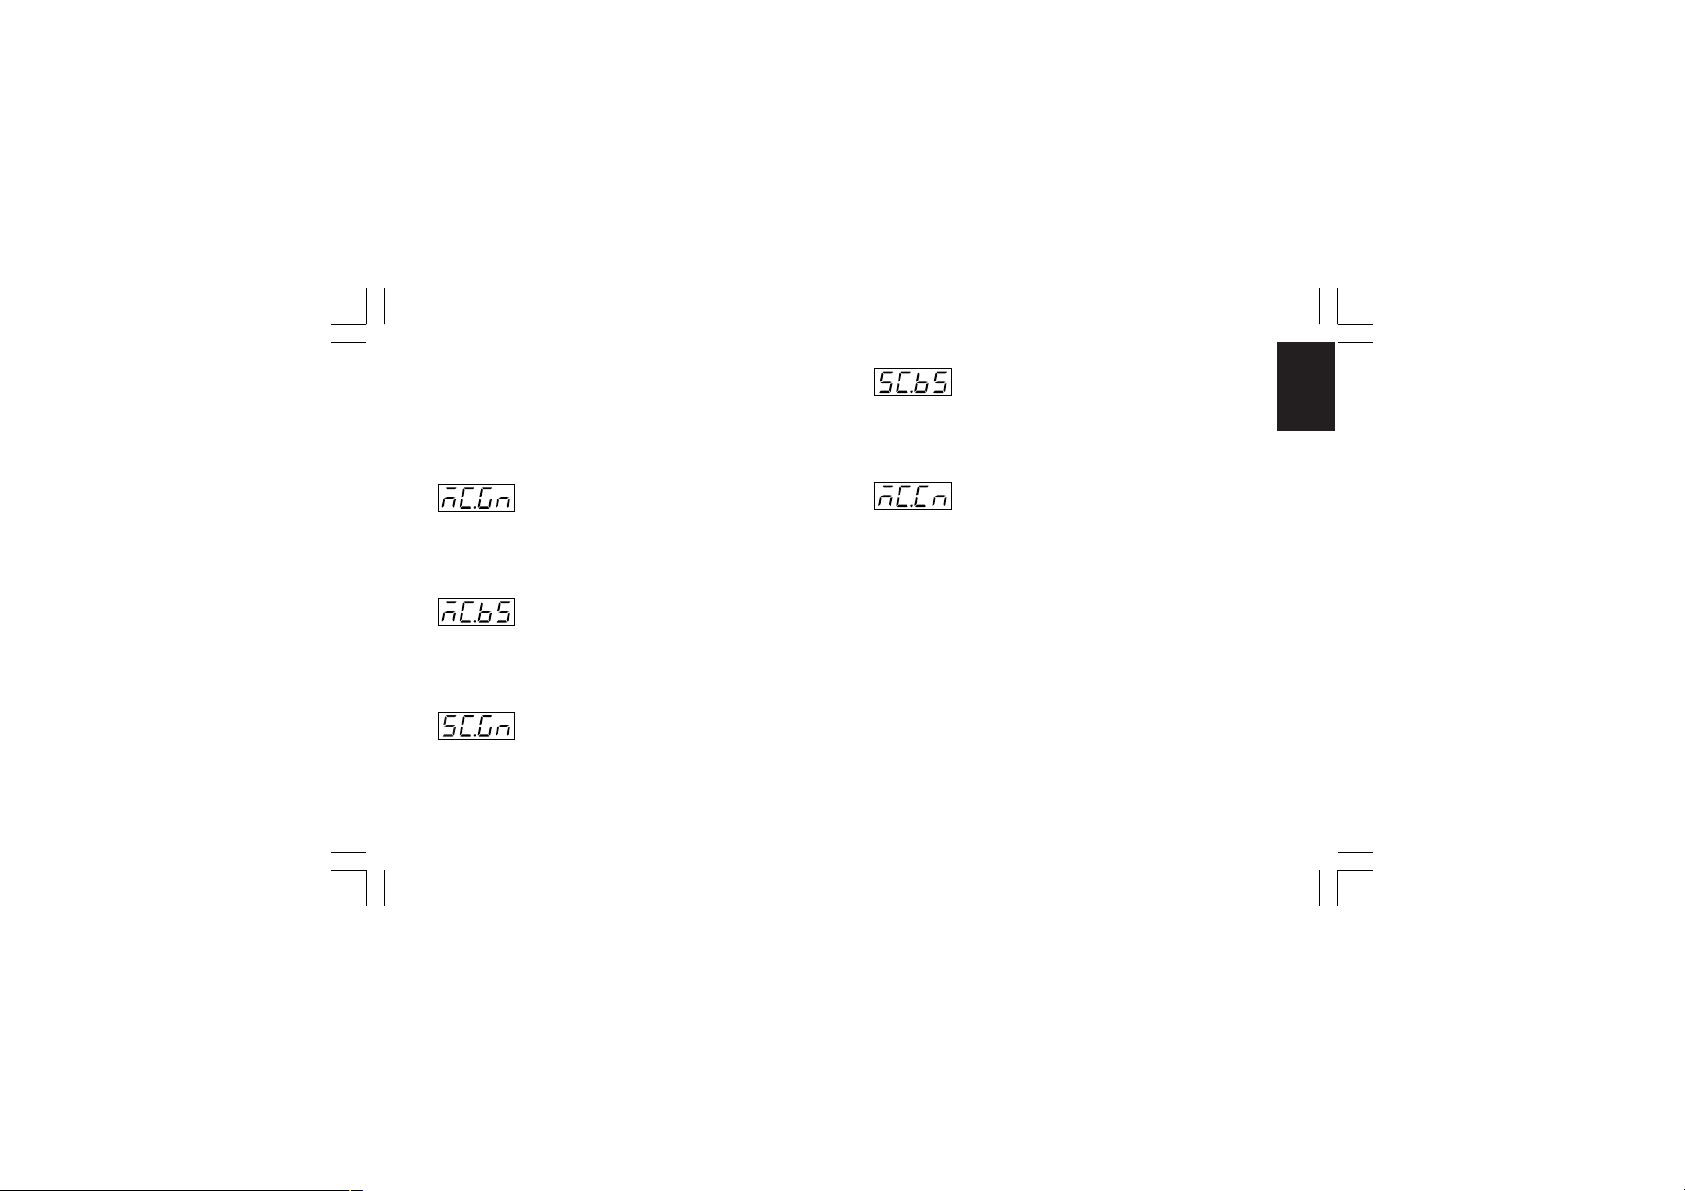
The bias and gain of the two split outputs are the following:
“ñC.bS” [C.F03] is the Bias 1 applied to the main output
“ñC.Gn” [C.F02] is the Gain 1 applied to the main output
“SC.bS” [C.F05] is the Bias 2 applied to the secondary output
“SC.Gn” [C.F04] is the Gain 2 applied to the secondary output
- Secondary control output bias - [C.F05]
This parameter will be available only when the split range is
enabled ("SPLt." [C.F01] = "Enb").
Range: from -100.0 to 100.0 % of the output span.
CnF. 3
- Main control output gain - [C.F02]
This parameter will be available only when the split range is
enabled ("SPLt." [C.F01] = "Enb").
Range: from 0.50 to 5.00.
- Main control output bias - [C.F03]
This parameter will be available only when the split range is
enabled ("SPLt." [C.F01] = "Enb").
Range: from -100.0 to 100.0 % of the output span.
- Secondary control output gain - [C.F04]
This parameter will be available only when the split range is
enabled ("SPLt." [C.F01] = "Enb").
Range: from 0.50 to 5.00
Xkc-1-C0.P65 5/29/02, 11:59 AM45
- Main control output conditioning - [C.F06]
This parameter will be available only when main control output is
configured.
Range: norñ = The control output is calculated by the PID
CñPL = The control output is complemented (100-PID
calculated value)
Ouic = The control output is conditioned to match a
“QUICK OPENING” flow characteristic
Eou = The control output is conditioned to match an
“EQUAL PERCENTAGE” flow characteristic
NOTE about output conditioning
Sometimes non linear valves are used where a linear valve is
suitable.
In these cases, it is advisable to linearize the ratio between flow
rate and valve travel in order to obtain a better control of the
process.
45
Page 50
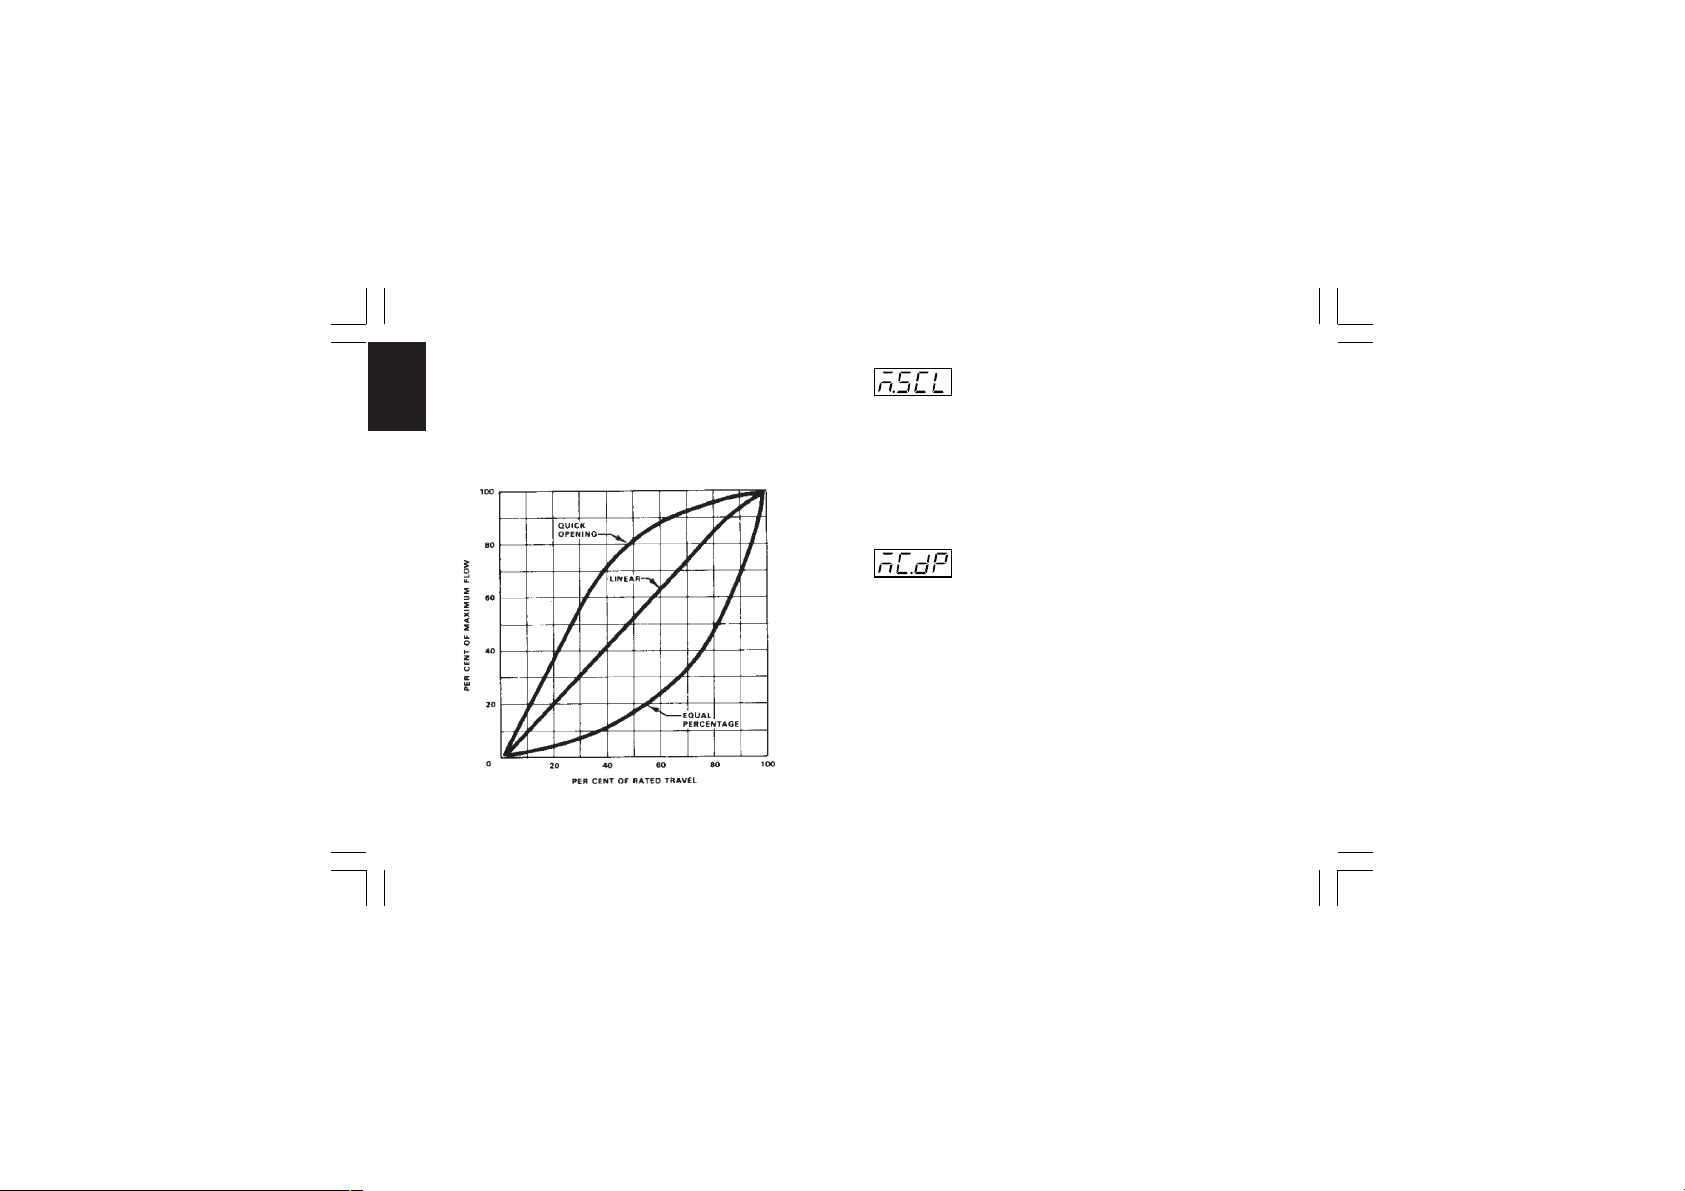
This instrument allows you to select an output linearization in
accordance with the two most common valve flow characteristics:
CnF. 3
- Quick opening
- Equal percentage.
Xkc-1-C0.P65 5/29/02, 11:59 AM46
- Main control output in engineering unit
This parameter will be available only when main control output is
configured.
Range: nO = Scalable is not required
NOTE: This scaling allows you to display the output value in
engineering units instead of in percent.
This parameter will be available only when "ñ.SCL" ("Main
control output in engineering units" [C.F07]) is set to "yES".
Range:
- [C.F07]
YES = Scalable is required
- Main output decimal point position - [C.F08]
----. = No decimal figure
---.- = One decimal figure.
--.-- = Two decimal figures.
46
Page 51
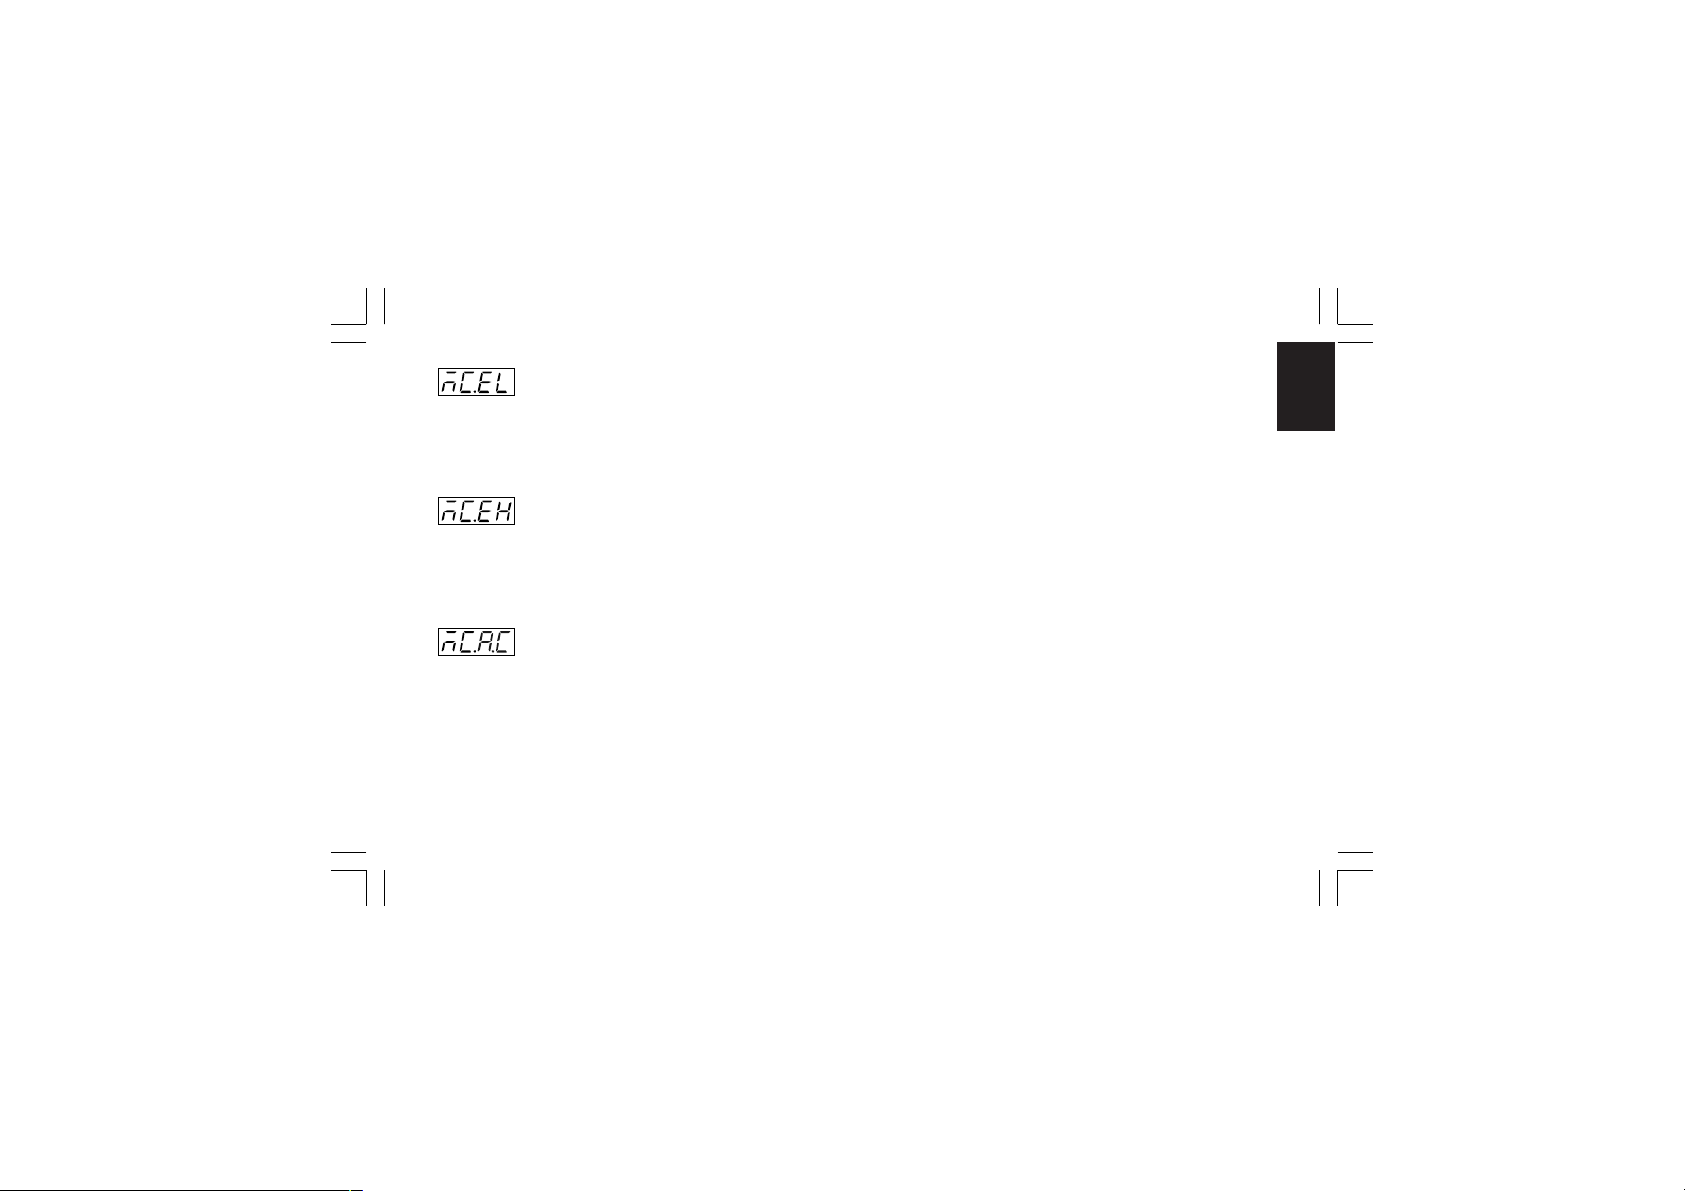
- Main output initial scale readout - [C.F09]
This parameter will be available only when "ñ.SCL" ("Main
control output in engineering units" [C.F07]) is set to "YES".
Range: from -199 to 999
- Main output full scale readout - [C.F10]
This parameter will be available only when "ñ.SCL" ("Main
control output in engineering units" [C.F07]) is set to "YES".
Range: from -199 to 999
- Main output auxiliary conditioning - [C.F11]
This parameter will be available only when main control output is
configured and “ñC.Cn” ("Main control output conditioning"
[C.F06]) is different from “norñ”.
Range: bEFr = The functions listed at Note (**) are calculated
before to apply the action selected by “ñC.Cn”
("Main control output conditioning" [C.F06])
parameter.
Xkc-1-C0.P65 5/29/02, 11:59 AM47
AFtr = The functions listed at Note (**) are calculated
after to apply the action selected by “ñC.Cn”
(“Main control output conditioning” [C.F06])
parameter.
Note (**)
- "Main control output limiters" - for more details see [r.E04]
and [r.E05] parameters.
- "Main control output max rate of rise" (see [r.E06]).
- "Control output display value" - for more details see "Display
function" paragraph at pag. 62 and [C.F07], [C.F08], [C.F09]
and [C.F10] parameters.
- "Threshold for alarm on control output value" - for more
details see [r.F01], [r.F05] [r.F09] and [r.F13] parameters.
- The control output value displayed by bargraph.
47
CnF. 3
Page 52
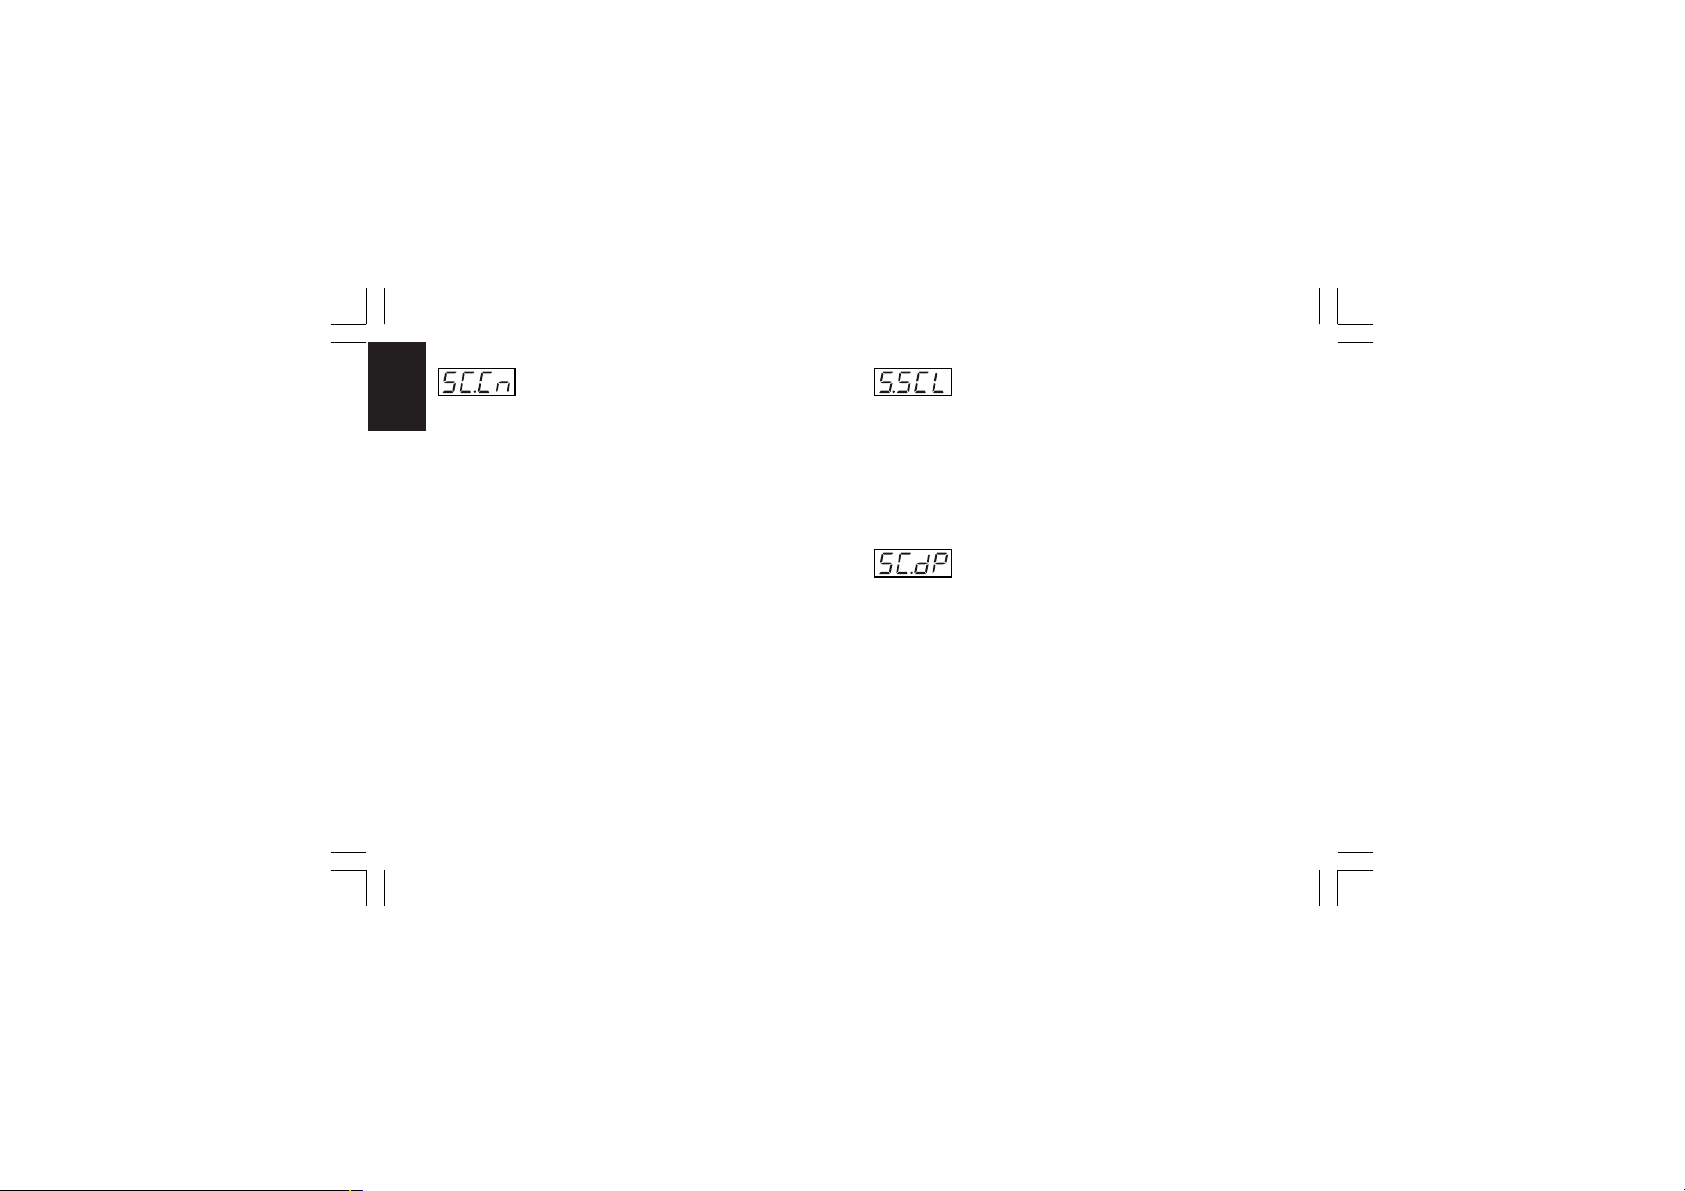
- Secondary control output conditioning
This parameter will be available only when secondary control
CnF. 3
output is configured.
Range: norñ = The control output is calculated by the PID
For more details see also NOTE about output conditioning at
page 43.
Xkc-1-C0.P65 5/29/02, 11:59 AM48
- [C.F12]
CñPL = The control output is complemented (100-PID
calculated value)
Ouic = The control output is conditioned to match a
“QUICK OPENING” flow characteristic
Eou = The control output is conditioned to match an
“EQUAL PERCENTAGE” flow characteristic
- Secondary control output in engineering unit
This parameter will be available only when secondary control
output is configured.
Range: nO = Scalable is not required
NOTE: This scaling allows to display the output value in
engineering units instead of in percent.
This parameter will be available only when "S.SCL" ("Secondary
control output in engineering units" [C.F13]) is set to "YES".
Range:
- [C.F13]
YES = Scalable is required
- Secondary control output decimal point
position - [C.F14]
----. = No decimal figure
---.- = One decimal figure.
--.-- = Two decimal figures.
48
Page 53
- Secondary control output initial scale value
- [C.F15]
This parameter will be available only when "S.SCL" ("Secondary
control output in engineering units" [C.F13]) is set to "YES".
Range: from -199 to 999
AFtr = The functions listed at Note (**) are calculated
after to apply the action selected by “SC.Cn”
(“Secondary control output conditioning”
[C.F12]) parameter.
CnF. 3
- Secondary control output full scale value
- [C.F16]
This parameter will be available only when "S.SCL" ("Secondary
control output in engineering units" [C.F13]) is set to "YES".
Range: From -199 to 999
- Secondary output auxiliary conditioning
- [C.F17]
This parameter will be available only when secondary control
output is configured and “SC.Cn” ("Secondary control output
conditioning" [C.F12]) is different from “norñ”.
Range: bEFr = The functions listed at Note (**) are calculated
before to apply the action selected by “SC.Cn”
("Secondary control output conditioning"
[C.F12]) parameter.
Xkc-1-C0.P65 5/29/02, 11:59 AM49
General note on configuration group 3
Exiting from the configuration group 3 the instrument automatically tests the "SPLt" parameter (Split range [C.F01]). When
"SPLt." parameter is enabled (= "Enb"), the instrument performs
the following actions:
1) If “Añ.UL” parameter ("Output value for AUTO to MAN
transfer [C.G04]) is lower than 0, it will be forced to “buñ“.
2) If the “SF.UL” parameter ("Output safety value" [C.G08]) is
lower than zero, it will be forced to zero.
3) If the “IP” parameter ("Integral pre-load" [r.d05] is lower than
zero, it will be forced to 50.0.
49
Page 54
CONFIGURATION GROUP 4 [C.Gxx]
AUXILIARY CONTROL CONFIGURATION
CnF. 4
- Manual function - [C.G03]
This parameter will be available only when at least one control
output is configured
Range: dIS = Manual function disabled
Enb = Manual function may be enabled
- Smart function - [C.G01]
This parameter will be available only when at least one control
output is configured
Range: dIS = Smart function disabled
Enb = Smart function may be enabled
- Control action type - [C.G02]
This parameter will be available only when at least one control
output is configured
Range: Pid = The process is controlled by PID actions
Pi = The process is controlled by PI actions
Xkc-1-C0.P65 5/29/02, 11:59 AM50
- Output value for AUTO to MAN transfer
- [C.G04]
This parameter will be available only when at least one control
output is configured and manual function is enabled (“ñAn.F”
[C.G03] = “Enb”)
Range: - from 0.0 to 100.0 % of the output span if device is
configured with only one control output
- from -100.0 to 100.0 of the output span if device is
configured with two control outputs (split range
excluded).
Above the value 100.0 the display shows “buñ.” meaning that
the transfer from AUTO to MANUAL is bumpless (the instrument
set for MANUAL mode the same power output used in AUTO
mode)
50
Page 55
NOTES:
1) When open loop servomotor control drive without valve
position indication is configured, this parameter is forced to
“buñ.” and it cannot be modified.
2) When open loop servomotor control drive with valve position
indication is configured and the transfer from AUTO to MAN
is required, the instrument is able to reach the value
programmed by this parameter using temporarily the valve
position value as a feedback.
- MANUAL to AUTO transfer type - [C.G05]
This parameter will be available only when at least one control
output is configured and manual function is enabled (“ñAn.F”
[C.G03] = “Enb”)
Range: buñ. = Bumpless balance transfer
buñ.b = Bumpless balanceless transfer (the operative
set point is aligned to the measure value)
NOTES:
1) The “alignment” is not performed if measure is in error
condition or Remote Set point is selected
2) The selected local set point will be changed even if it is
software protected.
Xkc-1-C0.P65 5/29/02, 11:59 AM51
- Device status at start up - [C.G06]
This parameter will be available only when at least one control
output is configured and manual function is enabled (“ñAn.F”
[C.G03] = “Enb”).
Range: Auto = It starts always in auto mode
ñan = It starts always in manual mode with power
output set to 0
Cnd.A = It starts in the same way it was left prior to
power shut down (if in manual mode the power
output is set to 0)
Cnd.b = It starts in the same way it was left prior to
power shut down (if in manual mode the power
output will be equal to the last value prior to
power shut down).
51
CnF. 4
Page 56
- Condition for output safety value - [C.G07]
This parameter will be available only when at least one control
CnF. 5
output is configured.
Ranges:
- When no output is configured as open loop servomotor
control, "SF.Cn" can be set as follows:
Std. = No safety value (“standard setting” see chapter
ERROR MESSAGES).
Ov.Un = Safety value applied when the instrument
detect an overrange or underrange condition of
the main input.
OvEr = Safety value applied when the instrument
detect an overrange condition of the main input.
Undr = Safety value applied when the instrument
detect an underrange condition of the main
input.
- When the open loop servomotor control is configured, "SF.Cn"
can be set as follows:
Std. = No safety value (“standard setting” see chapter
ERROR MESSAGES).
Cnd.A = When the instrument detects an overrange or
underrange condition of the main input, the
servomotor is driven to its high limit position.
Cnd.b = When the instrument detects an overrange or
Xkc-1-C0.P65 5/29/02, 11:59 AM52
underrange condition of the main input, the
servomotor is driven to its low limit position.
Cnd.C = When the instrument detects an overrange or
underrange condition of the main input, the
action on servomotor is the complement of
“standard” setting.
- Output safety value - [C.G08]
This parameter will be available only when "SF.Cn" [C.G07] is
equal to “Ov.Un”, “OvEr” or “Undr”or the parameter “A.I.Sc”
("Auxiliary input safety condition" [C.d15]) is equal to “Cnd.A”
Range:
- from 0.0 to 100.0 if device is configured with one control
output;
- from -100.0 to 100.0 if device is configured with two control
outputs (split range excluded).
52
Page 57
CONFIGURATION GROUP 5 [C.Hxx]
DIGITAL INPUT/OUTPUT CONFIGURATION
- Logic input 1 function - [C.H01]
Range: nonE = Input contact not used
SP1.2 = Input contact used for SP /SP2 set point
selection (see note 2)
SP3.4 = Input contact used for SP3/SP4 set point
selection (see note 2)
SP.L.r = Input contact used for Local/Remote set point
selection (Remote when logic level is “1”)
Au.ñA = Input contact used for Auto/Manual selection
(Manual when logic level is “1”)
O.LIñ = Input contact used for output limiter activation
(Output limited when logic level is “1”)
Hold = Input contact used to stop input sampling (Hold
function) (Stop sampling when logic level is “1”)
Xkc-1-C0.P65 5/29/02, 11:59 AM53
ñ.rSt = Input contact used to reset (acknowledge)
alarm (Reset when logic level is “1”)
rE.dr = Input contact used for Reverse/Direct control
action selection (Direct when logic level is “1”)
NOTES:
1) When logic input circuits are not mounted the middle display
will show “no.Pr” (not present).
2) When one logic input is set to “SP.1.2” and no other logic
input is set to “SP.3.4”, the relation between the logic level
and the selected set point is the following:
Logic level 0 = SP
Logic level 1 = SP2
When one logic input is set to “SP.1.2” and a second logic
input is set to “SP.3.4”, the relation between the logic levels
and the selected set point is the following:
“SP.3.4” “SP.1.2” Set point
level level selected
00SP
0 1 SP2
1 0 SP3
1 1 SP4
53
CnF. 5
Page 58
When one logic input is set to “SP.3.4” and no other logic
input is set to “SP.1.2”, the relation between the logic level
and the selected set point is the following:
CnF. 5
Logic level 0 = SP
Logic level 1 = SP3
- Logic input 1contact status - [C.H02]
This parameter will be available only when "d1.Fn" [C.H01] is
different from “nonE”.
Range: CLSd = The input is at logic level “1” when contact is
closed
OPEn = The input is at logic level “1” when contact is
open
Xkc-1-C0.P65 5/29/02, 11:59 AM54
- Logic input 2 function - [C.H03]
This parameter will be available only when input contact option
is fitted.
Range: nonE = Input contact not used
SP1.2 = Input contact used for SP /SP2 set point
selection (see note 2)
SP3.4 = Input contact used for SP3/SP4 set point
selection (see note 2)
SP.L.r = Input contact used for Local/Remote set point
selection (Remote when logic level is “1”)
Au.ñA = Input contact used for Auto/Manual selection
(Manual when logic level is “1”)
O.LIñ = Input contact used for output limiter activation
(Output limited when logic level is “1”)
Hold = Input contact used to stop input sampling (Hold
function) (Stop sampling when logic level is “1”)
ñ.rSt = Input contact used to reset (acknowledge)
alarm (Reset when logic level is “1”)
rE.dr = Input contact used for Reverse/Direct control
action selection (Direct when logic level is “1”)
NOTE: See also NOTE 2) of the "d1.Fn" ("Logic input 1 function"
[C.H01]) parameter.
54
Page 59
- Logic input 2 contact status - [C.H04]
This parameter will be available only when "d2.Fn" [C.H03] is
different from “nonE”.
Range: CLSd = The input is at logic level “1” when contact is
closed
OPEn = The input is at logic level “1” when contact is
open
- Logic input 3 function - [C.H05]
This parameter will be available only when input contact option
is fitted.
Range: nonE = Input contact not used
SP1.2 = Input contact used for SP /SP2 set point
selection (see note 2)
SP3.4 = Input contact used for SP3/SP4 set point
selection (see note 2)
SP.L.r = Input contact used for Local/Remote set point
selection (Remote when logic level is “1”)
Au.ñA = Input contact used for Auto/Manual selection
(Manual when logic level is “1”)
O.LIñ = Input contact used for output limiter activation
(Output limited when logic level is “1”)
Xkc-1-C0.P65 5/29/02, 11:59 AM55
Hold = Input contact used to stop input sampling (Hold
function) (Stop sampling when logic level is “1”)
ñ.rSt = Input contact used to reset (acknowledge)
alarm (Reset when logic level is “1”)
rE.dr = Input contact used for Reverse/Direct control
action selection (Direct when logic level is “1”)
NOTE: See also NOTE 2) of the "d1.Fn" ("Logic input 1 function"
[C.H01]) parameter.
- Logic input 3 contact status - [C.H06]
This parameter will be available only when "d3.Fn" [C.H05] is
different from “nonE”.
Range: CLSd = The input is at logic level “1” when contact is
closed
OPEn = The input is at logic level “1” when contact is
open
55
CnF. 5
Page 60
- Event 1 function - [C.H07]
This parameter will be available only when OUT 1 is configured
CnF. 5
as event annunciator ("O1.Fn" [C.E01] is equal to “Eun.1”).
Range: ñ.In.E= Error condition (Over-Under-Open-Shrt) on
main input (Logic level “1” when error occurs)
Cj.Er = Error condition on CJ measurement (Logic level
“1” when error occurs)
A.In.E= Error condition (Over-Under-Open) on auxiliary
input (Logic level “1” when error occurs)
ñEA.E = Error condition on any measurement (Logic
level “1” when error occurs)
Au.ñA = Auto/manual mode annunciator (Logic level “1”
when device is in manual mode)
SP.L.r = Local/Remote set point annunciator (Logic level
“1” when remote set point is used)
Xkc-1-C0.P65 5/29/02, 11:59 AM56
- Event 1 contact status - [C.H08]
This parameter will be available only when OUT 1 is configured
as event annunciator ("O1.Fn" [C.E01] is equal to “Eun.1”).
Range: CLSd = The output is at logic level “1” when contact is
closed
OPEn = The output is at logic level “1” when contact is
open
- Event 2 function - [C.H09]
This parameter will be available only when OUT 2 is configured
as event annunciator ("O2.Fn" [C.E02] is equal to “Eun.2”).
Range: ñ.In.E= Error condition (Over-Under-Open-Shrt) on
main input (Logic level “1” when error occurs)
Cj.Er = Error condition on CJ measurement (Logic level
“1” when error occurs)
A.In.E= Error condition (Over-Under-Open) on auxiliary
input (Logic level “1” when error occurs)
ñEA.E = Error condition on any measurement (Logic
level “1” when error occurs)
56
Page 61
Au.ñA = Auto/manual mode annunciator (Logic level “1”
when device is in manual mode)
SP.L.r = Local/Remote set point annunciator (Logic level
“1” when remote set point is used)
- Event 2 contact status - [C.H10]
This parameter will be available only when OUT 2 is configured
as event annunciator ("O2.Fn" [C.E02] is equal to “Eun.2”).
Range: CLSd = The output is at logic level “1” when contact is
closed
OPEn = The output is at logic level “1” when contact is
open
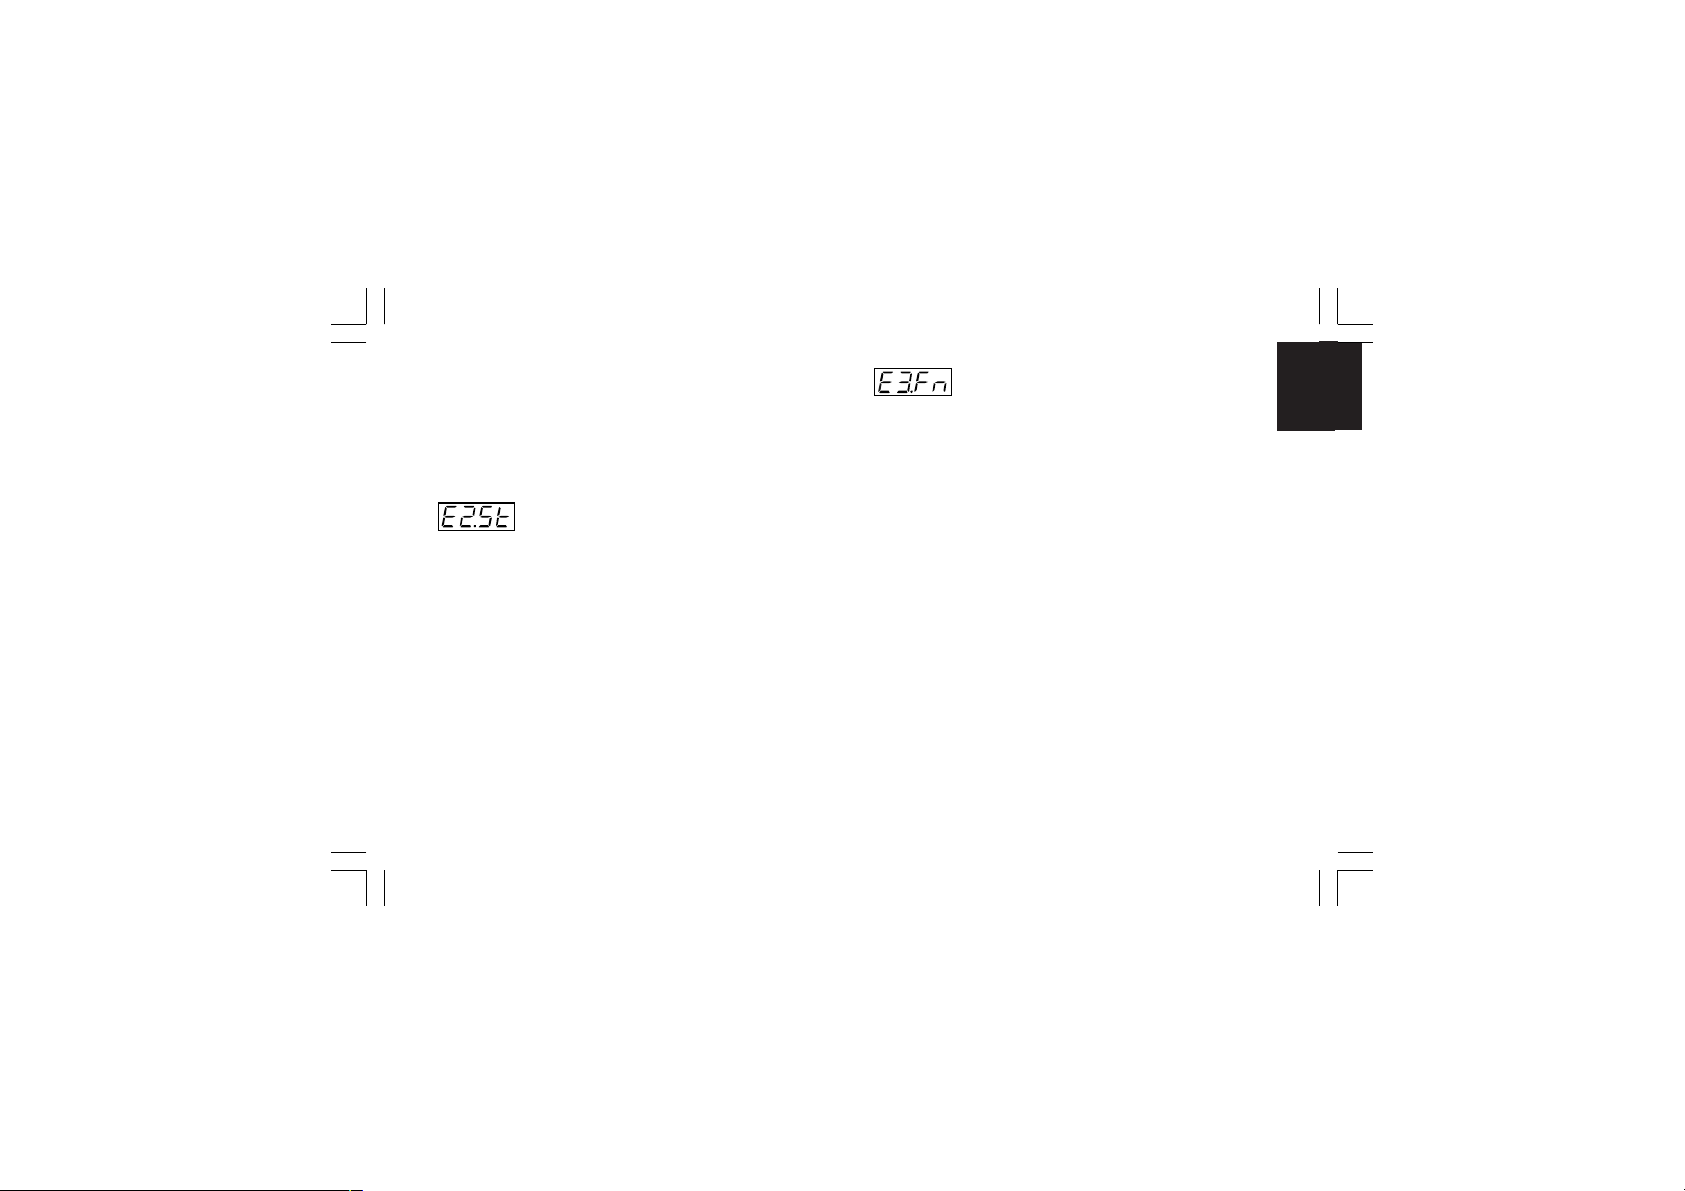
Xkc-1-C0.P65 5/29/02, 11:59 AM57
- Event 3 function - [C.H11]
This parameter will be available only when OUT 3 is configured
as event annunciator ("O3.Fn" [C.E03] is equal to “Eun.3”).
Range: ñ.In.E= Error condition (Over-Under-Open-Shrt) on
main input (Logic level “1” when error occurs)
Cj.Er = Error condition on CJ measurement (Logic level
“1” when error occurs)
A.In.E= Error condition (Over-Under-Open) on auxiliary
input (Logic level “1” when error occurs)
ñEA.E = Error condition on any measurement (Logic
level “1” when error occurs)
Au.ñA = Auto/manual mode annunciator (Logic level “1”
when device is in manual mode)
SP.L.r = Local/Remote set point annunciator (Logic level
“1” when remote set point is used)
57
CnF. 5
Page 62
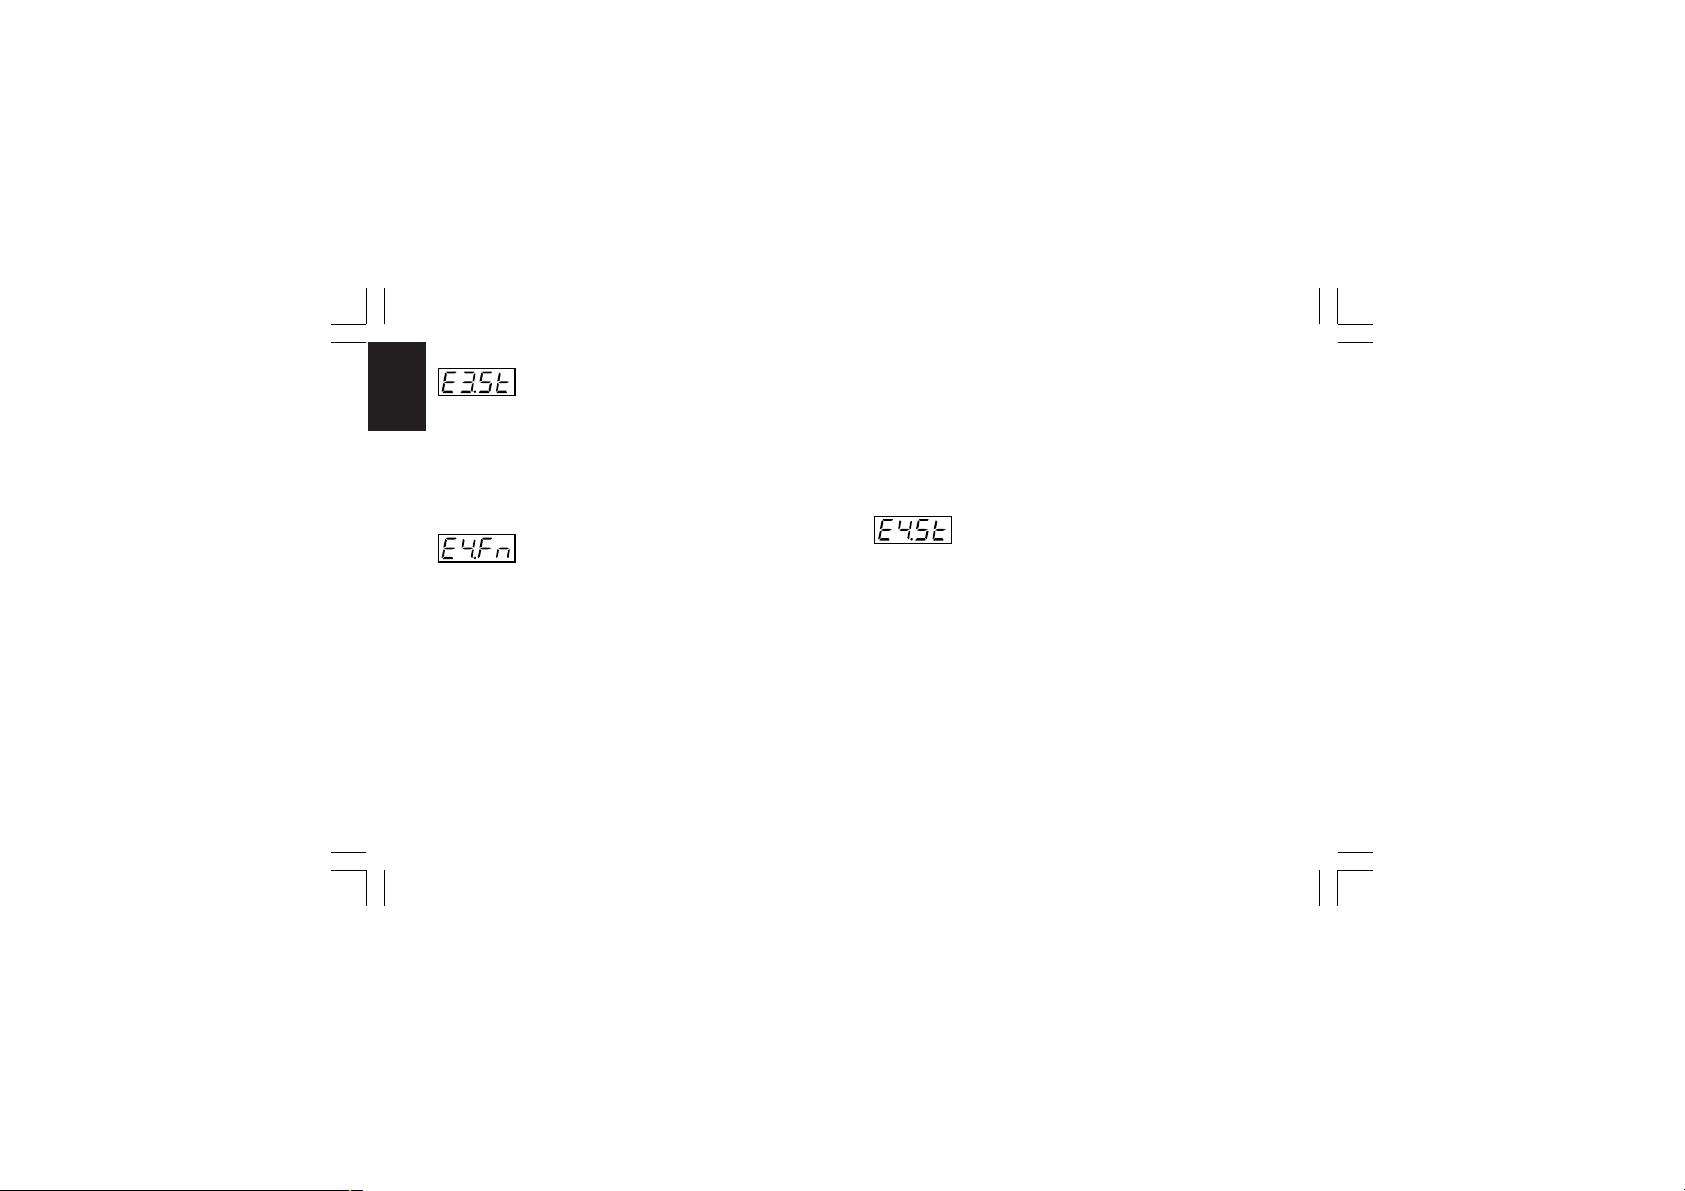
- Event 3 contact status - [C.H12]
This parameter will be available only when OUT 3 is configured
CnF. 6
as event annunciator ("O3.Fn" [C.E03] is equal to “Eun.3”).
Range: CLSd = The output is at logic level “1” when contact is
closed
OPEn = The output is at logic level “1” when contact is
open
- Event 4 function - [C.H13]
This parameter will be available only when OUT 4 is configured
as event annunciator ("O4.Fn" [C.E04] is equal to “Eun.4”).
Range: ñ.In.E= Error condition (Over-Under-Open-Shrt) on
main input (Logic level “1” when error occurs)
Cj.Er = Error condition on CJ measurement (Logic level
“1” when error occurs)
A.In.E= Error condition (Over-Under-Open) on auxiliary
input (Logic level “1” when error occurs)
ñEA.E = Error condition on any measurement (Logic
level “1” when error occurs)
Xkc-1-C0.P65 5/29/02, 11:59 AM58
Au.ñA = Auto/manual mode annunciator (Logic level “1”
when device is in manual mode)
SP.L.r = Local/Remote set point annunciator (Logic level
“1” when remote set point is used)
- Event 4 contact status - [C.H14]
This parameter will be available only when OUT 4 is configured
as event annunciator ("O4.Fn" [C.E04] is equal to “Eun.4”).
Range: CLSd = The output is at logic level “1” when contact is
closed
OPEn = The output is at logic level “1” when contact is
open
58
Page 63
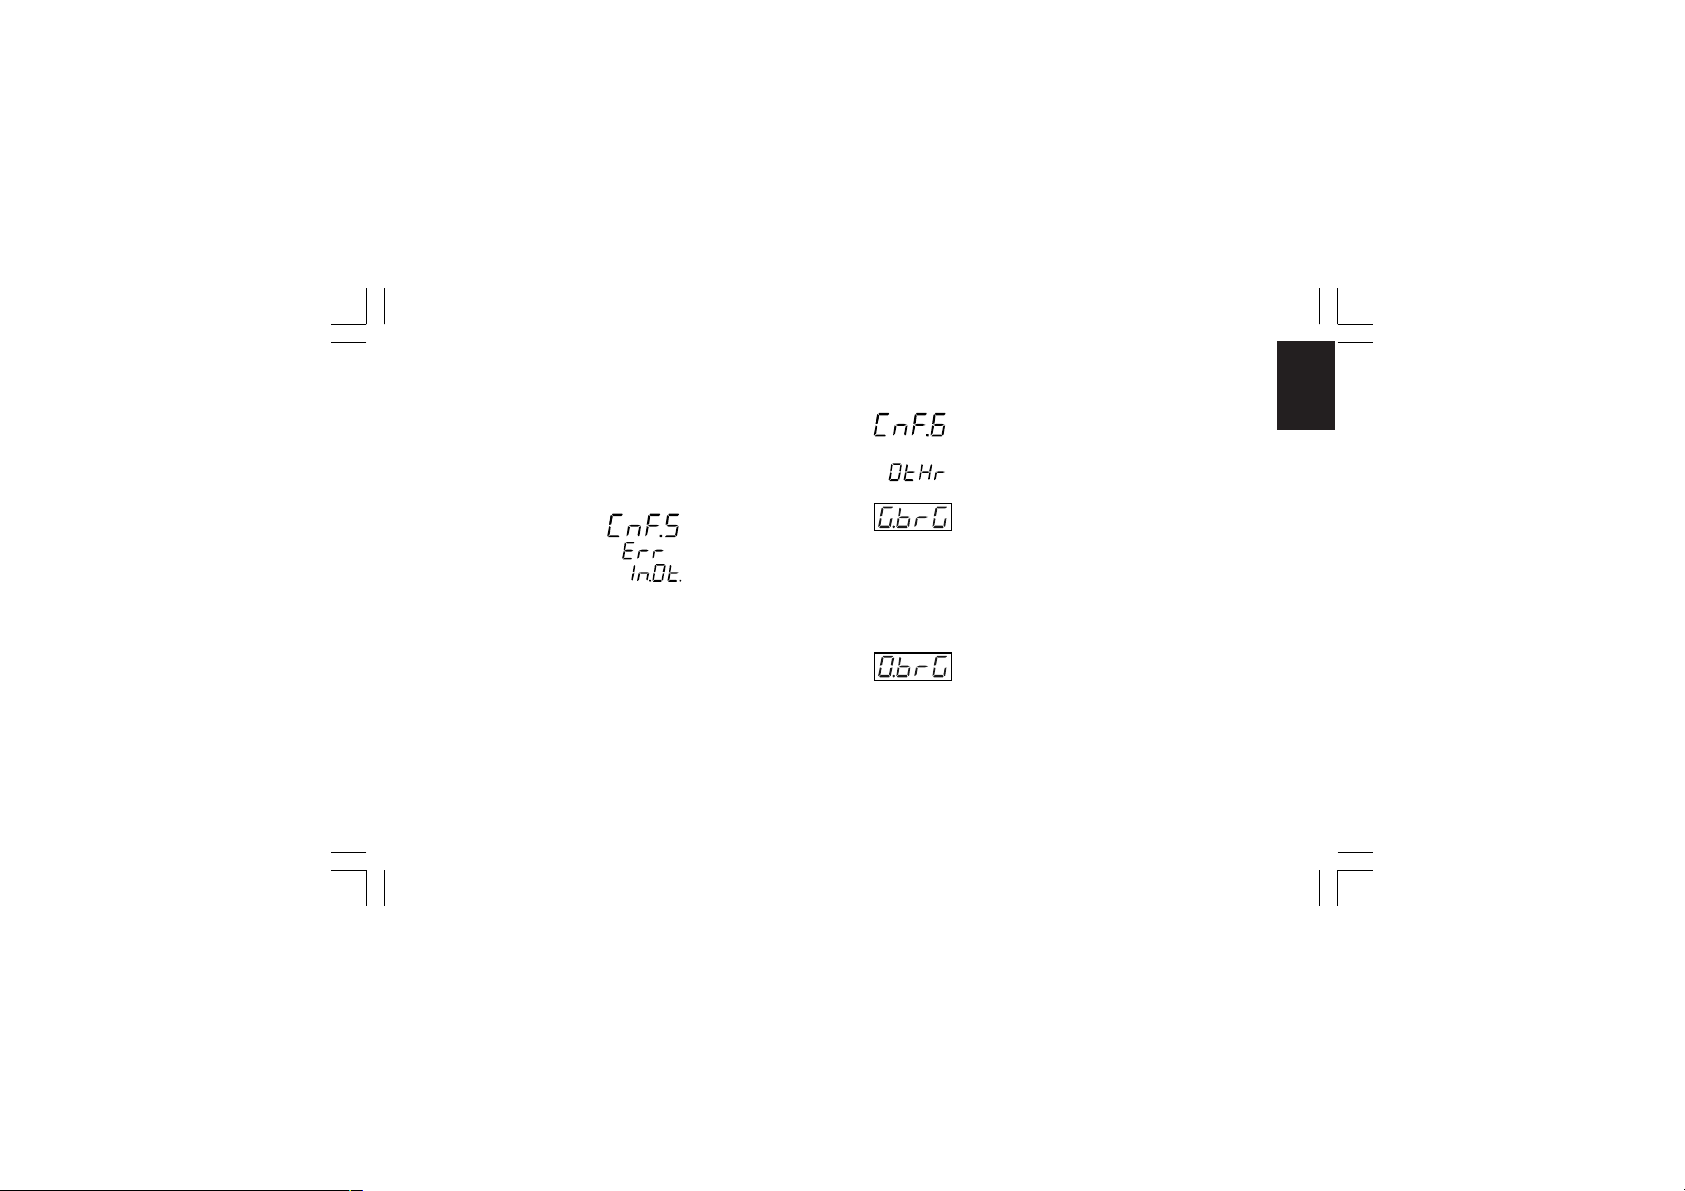
General notes on configuration group 5
1) Digital input function selection should be “consistent” with other
configuration parameters otherwise this digital input will remain
unused.
2) Changing menu the device will check that the same function is
not assigned to more than one digital input, otherwise the display
will show:
Xkc-1-C0.P65 5/29/02, 11:59 AM59
CONFIGURATION GROUP 6 [C.Ixx]
OTHERS CONFIGURATION PARAMETERS
CnF. 6
- Green bargraph function - [C.I01]
This parameter will be available for MKC models only.
Range: Pr.Ur = the green bargraph will show the process
variable value
DEV. = the green bargraph will show the deviation
(measured value minus set point)
- Orange bargraph function - [C.I02]
This parameter will be available for MKC models only.
Range: OP.SP= On bargraph is shown the operative set point
value
P.Out. = On bargraph is shown the process output value
59
Page 64
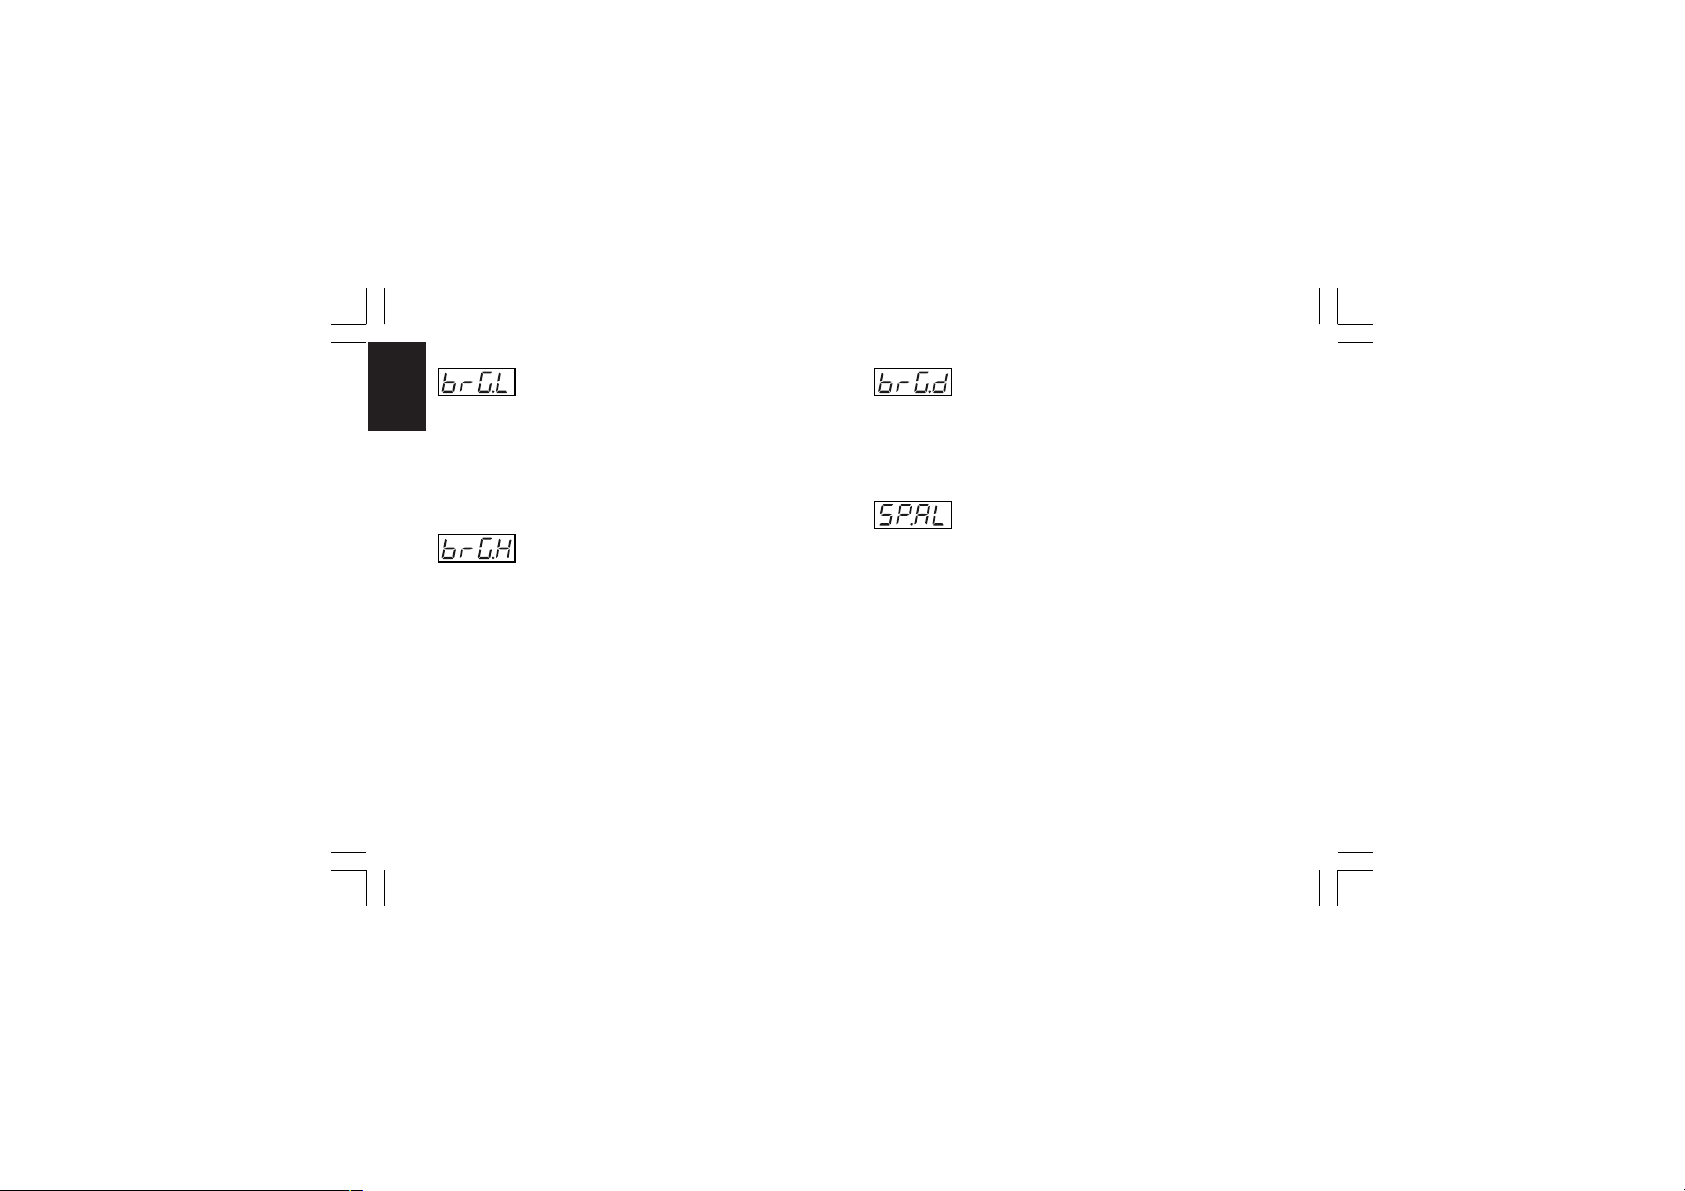
- Bargraph initial scale value - [C.I03]
This parameter will be available only for MKC models when
CnF. 6
“G.brG” [C.I01] is equal to “Pr.Ur” and/or “O.brG” [C.I02] is equal
to “OP.SP”.
Range: From “ñ.In.L” ("Read-out initial scale value" [C.d05]) to
“ñ.In.H” ("Read-out full scale value [C.d06])
- Bargraph full scale value - [C.I04]
This parameter will be available only for MKC models when
“G.brG” [C.I01] is equal to “Pr.Ur” and/or “O.brG” [C.I02] is equal
to “OP.SP”.
Range: From “ñ.In.L” ("Read-out initial scale value" [C.d05]) to
“ñ.In.H” ("Read-out full scale value [C.d06])
Xkc-1-C0.P65 5/29/02, 11:59 AM60
- Resolution of the deviation bargraph - [C.I05]
This parameter will be available only for MKC models when
“G.brG” [C.I01] is equal to “DEV.”.
Range: 1-2-5-10-20 or 50 = Digits per segment
- Operative set point alignment at start up
- [C.I06]
Range: ALG = At start up the operative set point is aligned to
measure value and then it will reach the
selected set point with the programmed ramp
(“Grd1” [r.E14] and “Grd2” [r.E15]).
n.ALG = At start up the operative set point is equal to the
selected set point
NOTE:The “ALG” selection has no effect when the measure is in
error condition or Remote Set point is selected.
60
Page 65
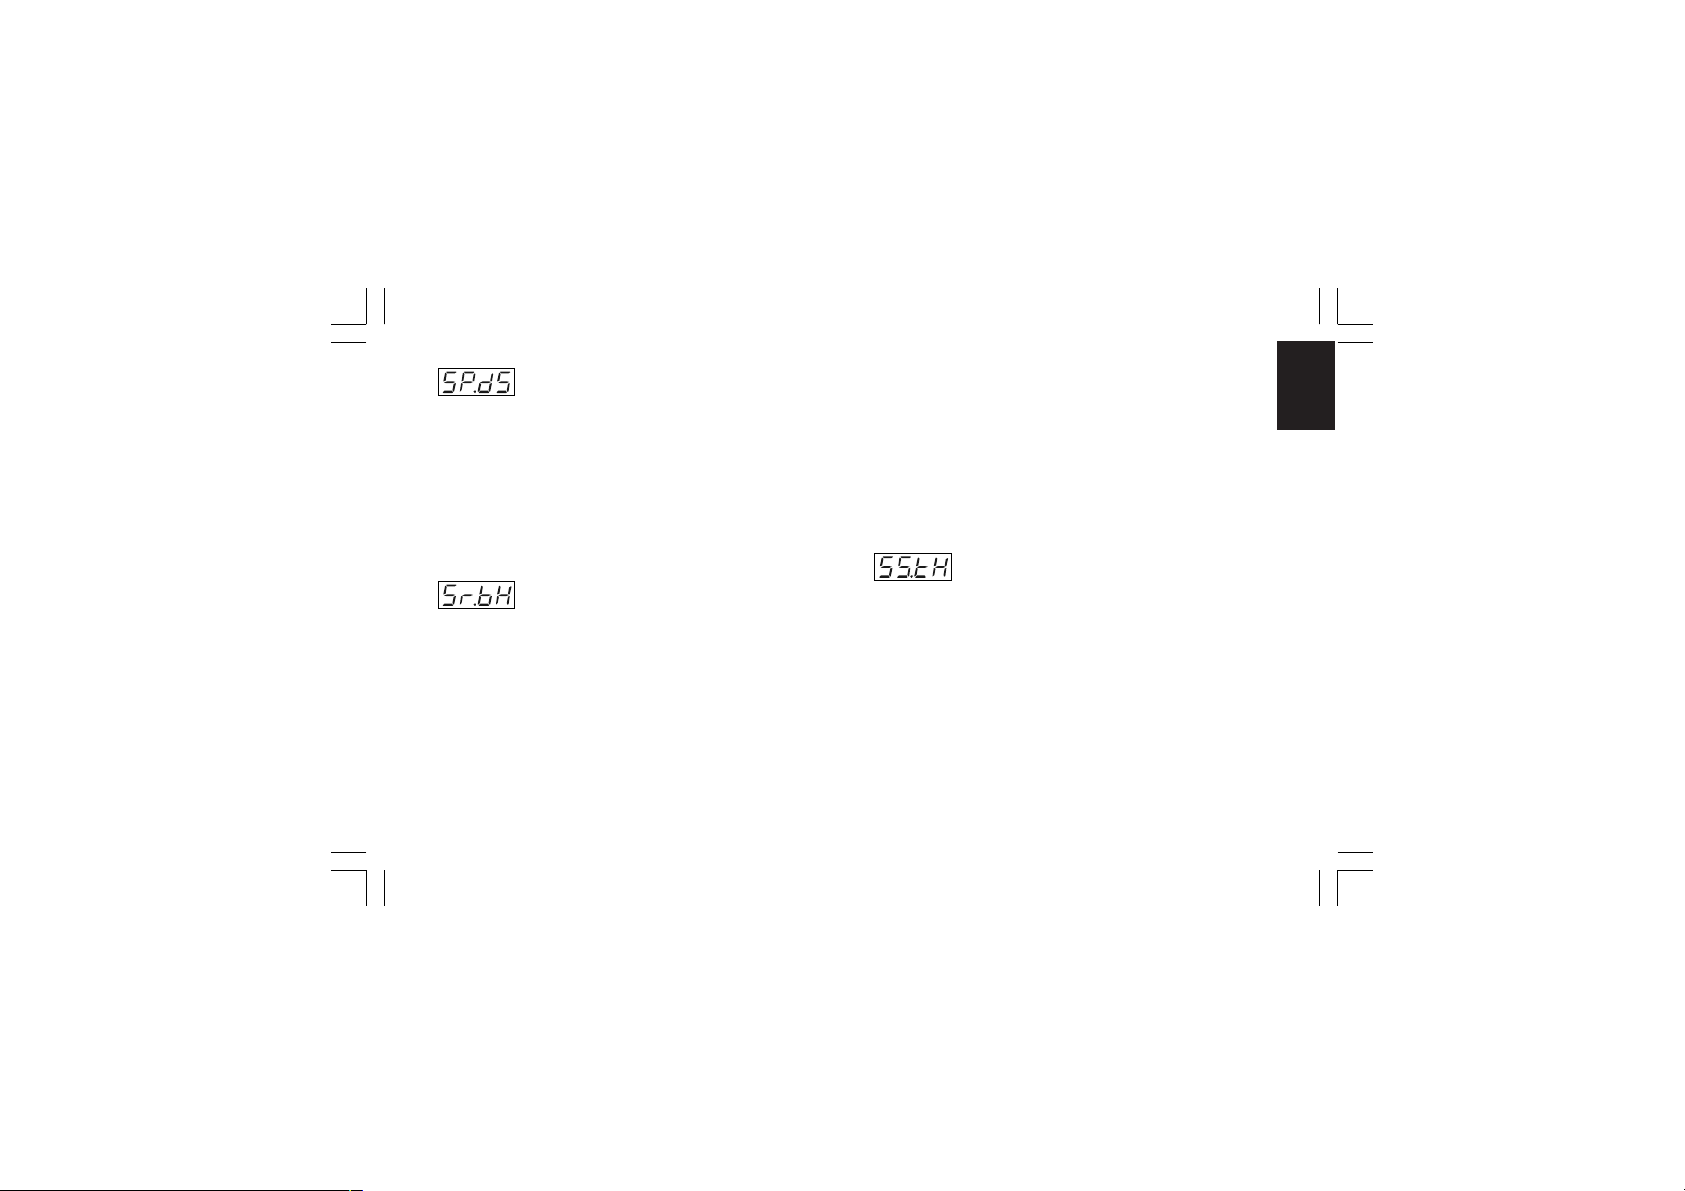
- Set point display type - [C.I07]
Range: Fn.SP = When device is in normal display mode and it is
performing a set point ramp, the middle display
will show the final set point value.
OP.SP= When device is in normal display mode and it is
performing a set point ramp, the middle display
will show the operative set point value.
NOTE: This selection has effect only when local set points are
used
- Servomotor behaviour when the output
power is limited - [C.I08]
This parameter will be available only when the close loop
servomotor control drive is configured
Range: bAL = When the PID output reaches the specific
output limits ("Main control output low limit"
[r.E04] or "Main control output high limit" [r.E05]
or "Secondary control output low limit" [r.E08] or
"Secondary control output high limit" [r.E09])
the instrument will reach the respective limit
and than it will maintain the output relay in open
condition.
Xkc-1-C0.P65 5/29/02, 11:59 AM61
n.bAL = When PID value is higher than "Main control
output high limit" [r.E05] or "Secondary control
output high limit" [r.E09] the OUT 3 (s) relay
contact is ever closed.
When PID value is lower than "Main control
output low limit" [r.E04] or "Secondary control
output low limit" [r.E08] the OUT 4 (t) relay
contact is ever closed.
- Input threshold to enable the soft start
- [C.I09]
Range: for TC/RTD ranges - within the input range;
for linear input - within “ñ.In.L” ("Read-out initial scale
value" [C.d05]) and ”ñ.In.H” ("Read-out full
scale value" [C.d06]).
NOTE: At start up if the measured value is lower than threshold
value, the device maintains the output power limiting (”ñ.OLL”
[r.E04], ”ñ.OLH” [r.E05], ”S.OLL” [r.E08] and ”S.OLH” [r.E09]) for
a programmed time (“tOL” [rE.16]).
This function is called “soft start”
This threshold value has no effect if “tOL” [rE.16] = InF or when
one logic input is configured for output limiter activation
61
CnF. 6
Page 66
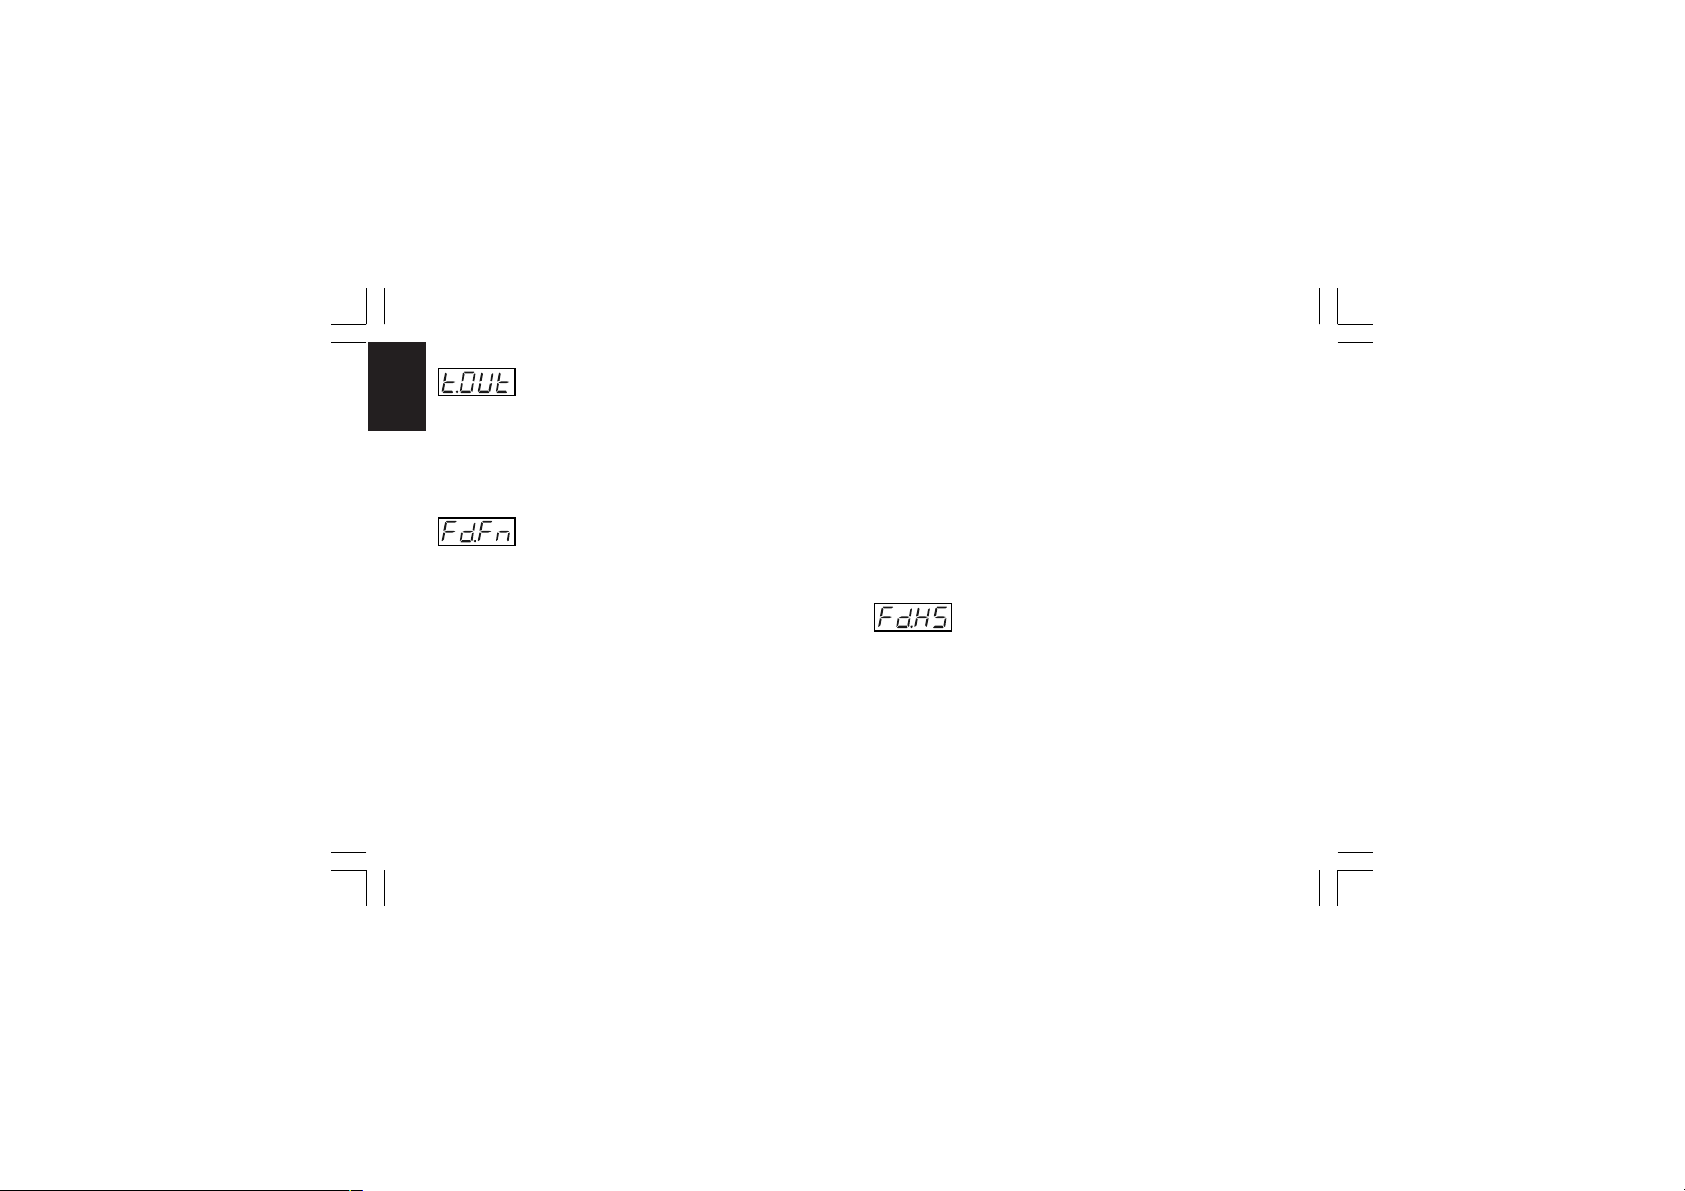
- Time out selection - [C.I10]
Range: tñ.10 = 10s time out
CnF. 6
tñ.30 = 30s time out
NOTE: for more details see "NOTE 2" at page 26.
- Out failure detection (OFD) - [C.I11]
This parameter will be available only when the option is fitted
and the main and/or the secondary output is configured as time
proportional control output
Range: nonE = Function not provided
ñC.On = Set “Fd.Fn” to “ñC.On” when the load under test
is energized during the ON status of the main
output (relay energized or SSR output status 1).
ñC.OF= Set “Fd.Fn” to “ñC.OF” when the load under
test is energized during the OFF status of the
main output (relay de-energized or SSR output
status 0).
SC.On= Set “Fd.Fn” to “SC.On” when the load under test
Xkc-1-C0.P65 5/29/02, 11:59 AM62
is energized during the ON status of the second-
ary output (relay energized or SSR output status
1).
SC.OF= Set “Fd.Fn” to “SC.OF” when the load under test
is energized during the OFF status of the second-
ary output (relay de-energized or SSR output
status 0).
NOTE: When the option is not fitted the middle display will show
“no.Pr”
- Primary current of the current transformer
- [C.I12]
This parameter will be available only when “Fd.Fn” [C.I11] is
different from “nonE”
Range: From 10 A to 100 A
62
Page 67
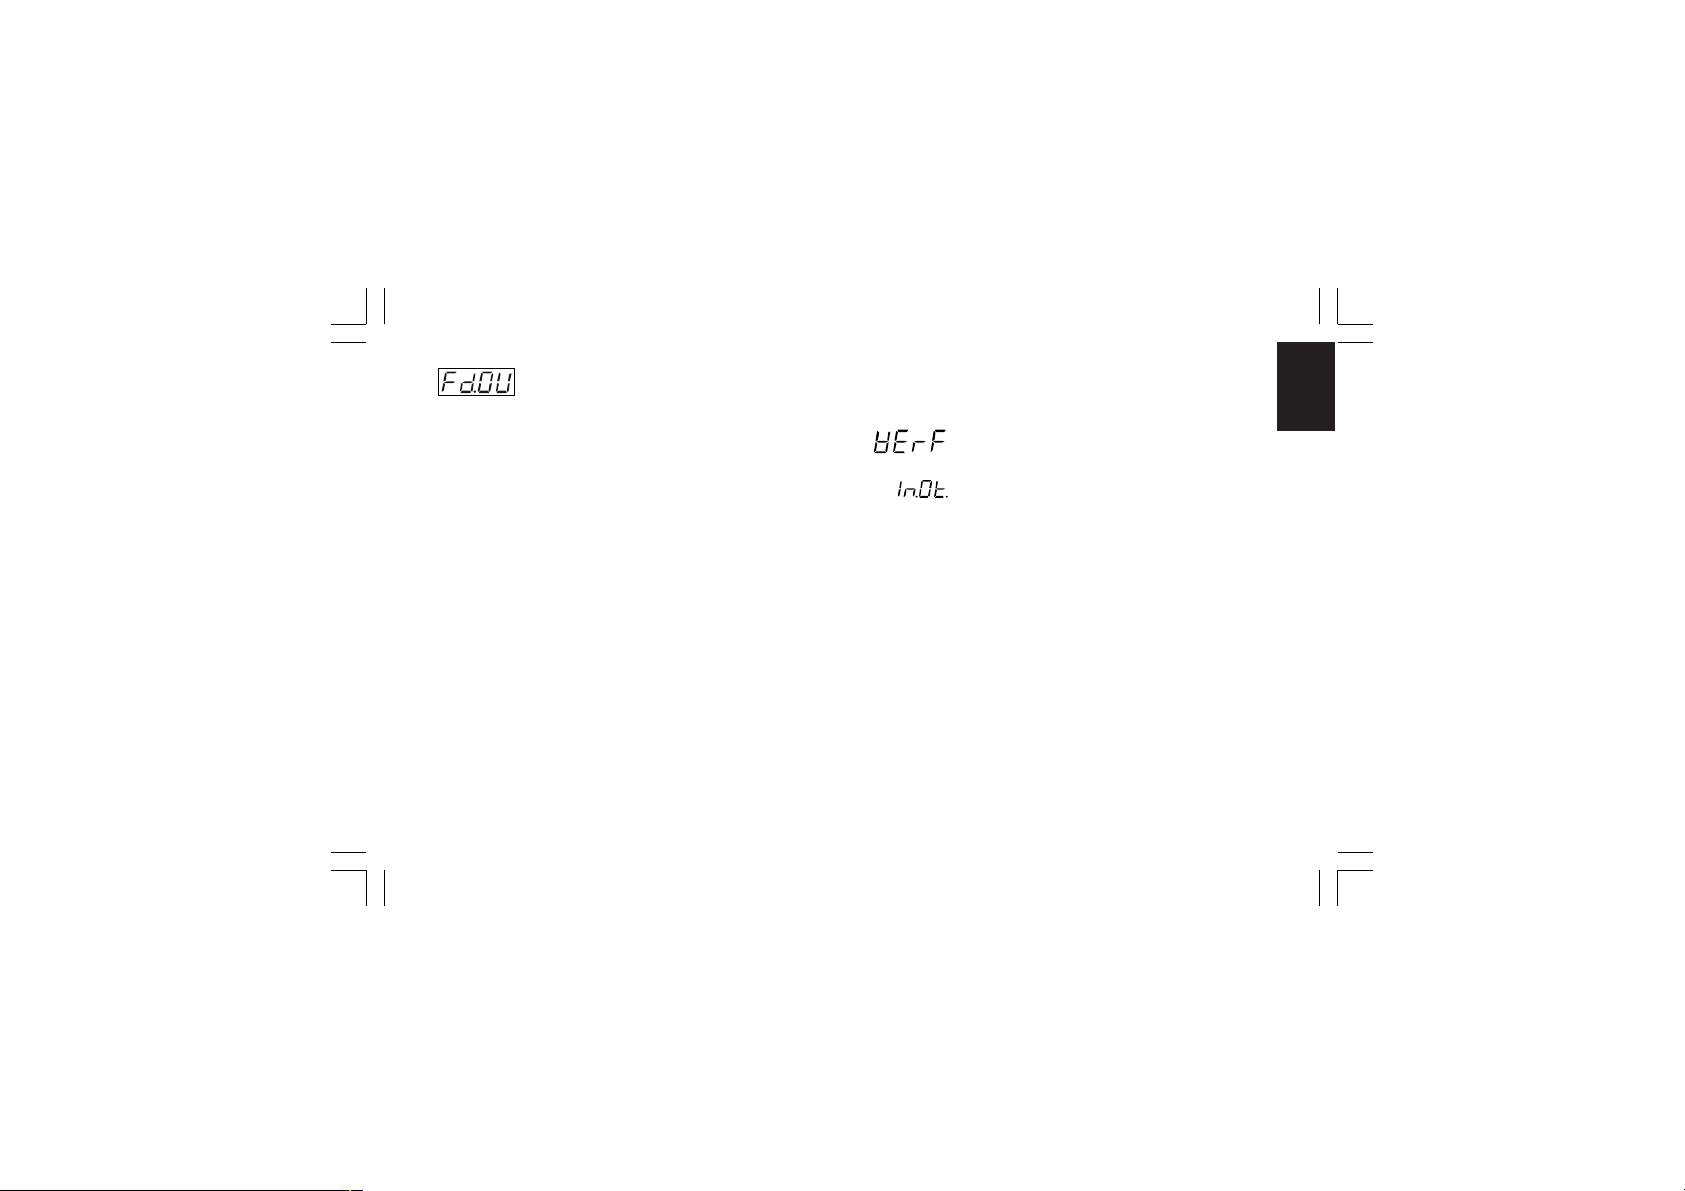
- Out failure detection - output assignment
- [C.I13]
This parameter will be available only when “Fd.Fn” [C.I11] is
different from “nonE”
Range: nonE = The "Out failure detection" alarm is signalled
only on display
OUt.1 = The "Out failure detection" alarm is signalled
on OUT 1
OUt.2 = The "Out failure detection" alarm is signalled on
OUT 2
OUt.3 = The "Out failure detection" alarm is signalled on
OUT 3
OUt.4 = The "Out failure detection" alarm is signalled on
OUT 4
NOTE: "Out failure detection "alarm annunciator cannot be
assigned to an output just configured as control output.
Xkc-1-C0.P65 5/29/02, 11:59 AM63
CONFIGURATION GROUP 7 [C.Lxx]
INPUT/OUTPUT TEST
CnF. 7
This group is displayed only when configuration modify mode is
enabled.
This group allows you to verify the correct working of:
- the relay outputs (OUT 1 up to OUT4),
- digital inputs (diG.1 up to diG.3),
- the inputs from In1 up to In8 and the relays of the outputs from
OUT10 up to OUT19, if the optional I/O card is fitted.
When an output is in "On" status, the related LED will light up
63
Page 68
C.L01 OUT 1 status
Upper display: VErF
Lower display: OU.1
CnF. 7
Range: On = Output enabled (relay energized)
OFF = Output disabled (relay deenergized)
NOTE: By pushing the s or t key it is possible to change
the output state. The setting above described is the
same for the remaining outputs.
C.L02 OUT 10 status
This parameter is available only if the optional card is fitted.
Upper display: VErF
Lower display: OU.10
Range: On = Output enabled (relay energized)
OFF = Output disabled (relay deenergized)
NOTE: By pushing the s or t key it is possible to change
the output state. The setting above described is the
same for the remaining outputs.
Xkc-1-C0.P65 5/29/02, 11:59 AM64
C.L03 Digital input dIG.1 status
Upper display: VErF
Lower display: dIG.1
Range: Open = Input open
CLSd = Input closed
NOTE:The setting above described is the same for the
remaining inputs.
C.L04 Digital input In.1 status
This parameter is available only if the optional card is fitted.
Upper display: VErF
Lower display: In.1
Range: Open = Input open
CLSd = Input closed
NOTE:The setting above described is the same for the
remaining inputs.
64
Page 69
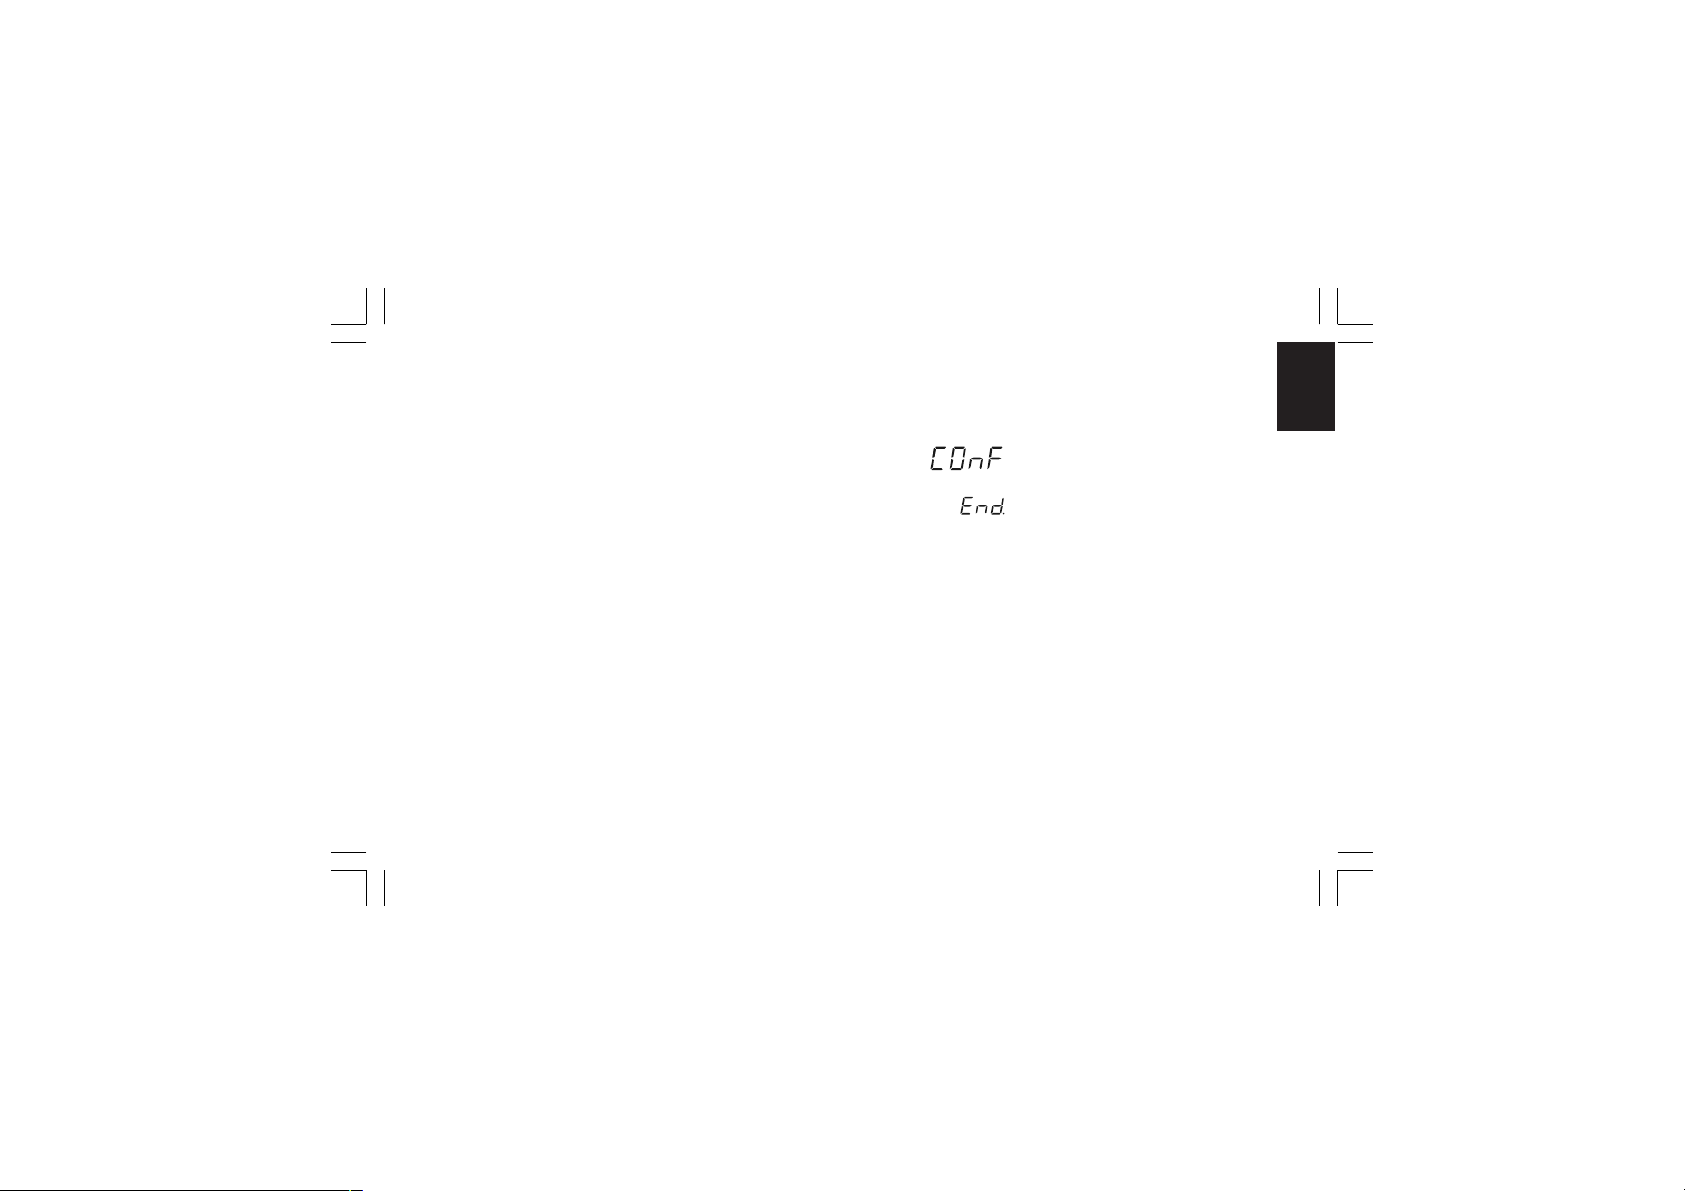
General note for configuration group "VErF"
Returning in the "run time mode", the instrument restarts to
control the process, the settings performed into this group do not
affect the working settings.
CONFIGURATION GROUP END [C.Lxx]
END CONFIGURATION
This group will be displayed only when configuration modify
mode is enabled.
CnF. END
Xkc-1-C0.P65 5/29/02, 11:59 AM65
Range: nO = with this selection the instrument comes back to
the first display of the configuration modify
mode
YES = this selection terminate the configuration modify
mode; the instrument preforms an automatic
reset and restarts the run time mode.
Pushing ”s” or “t” push-button select the desired action and then
push “MENU” push-button.
65
Page 70
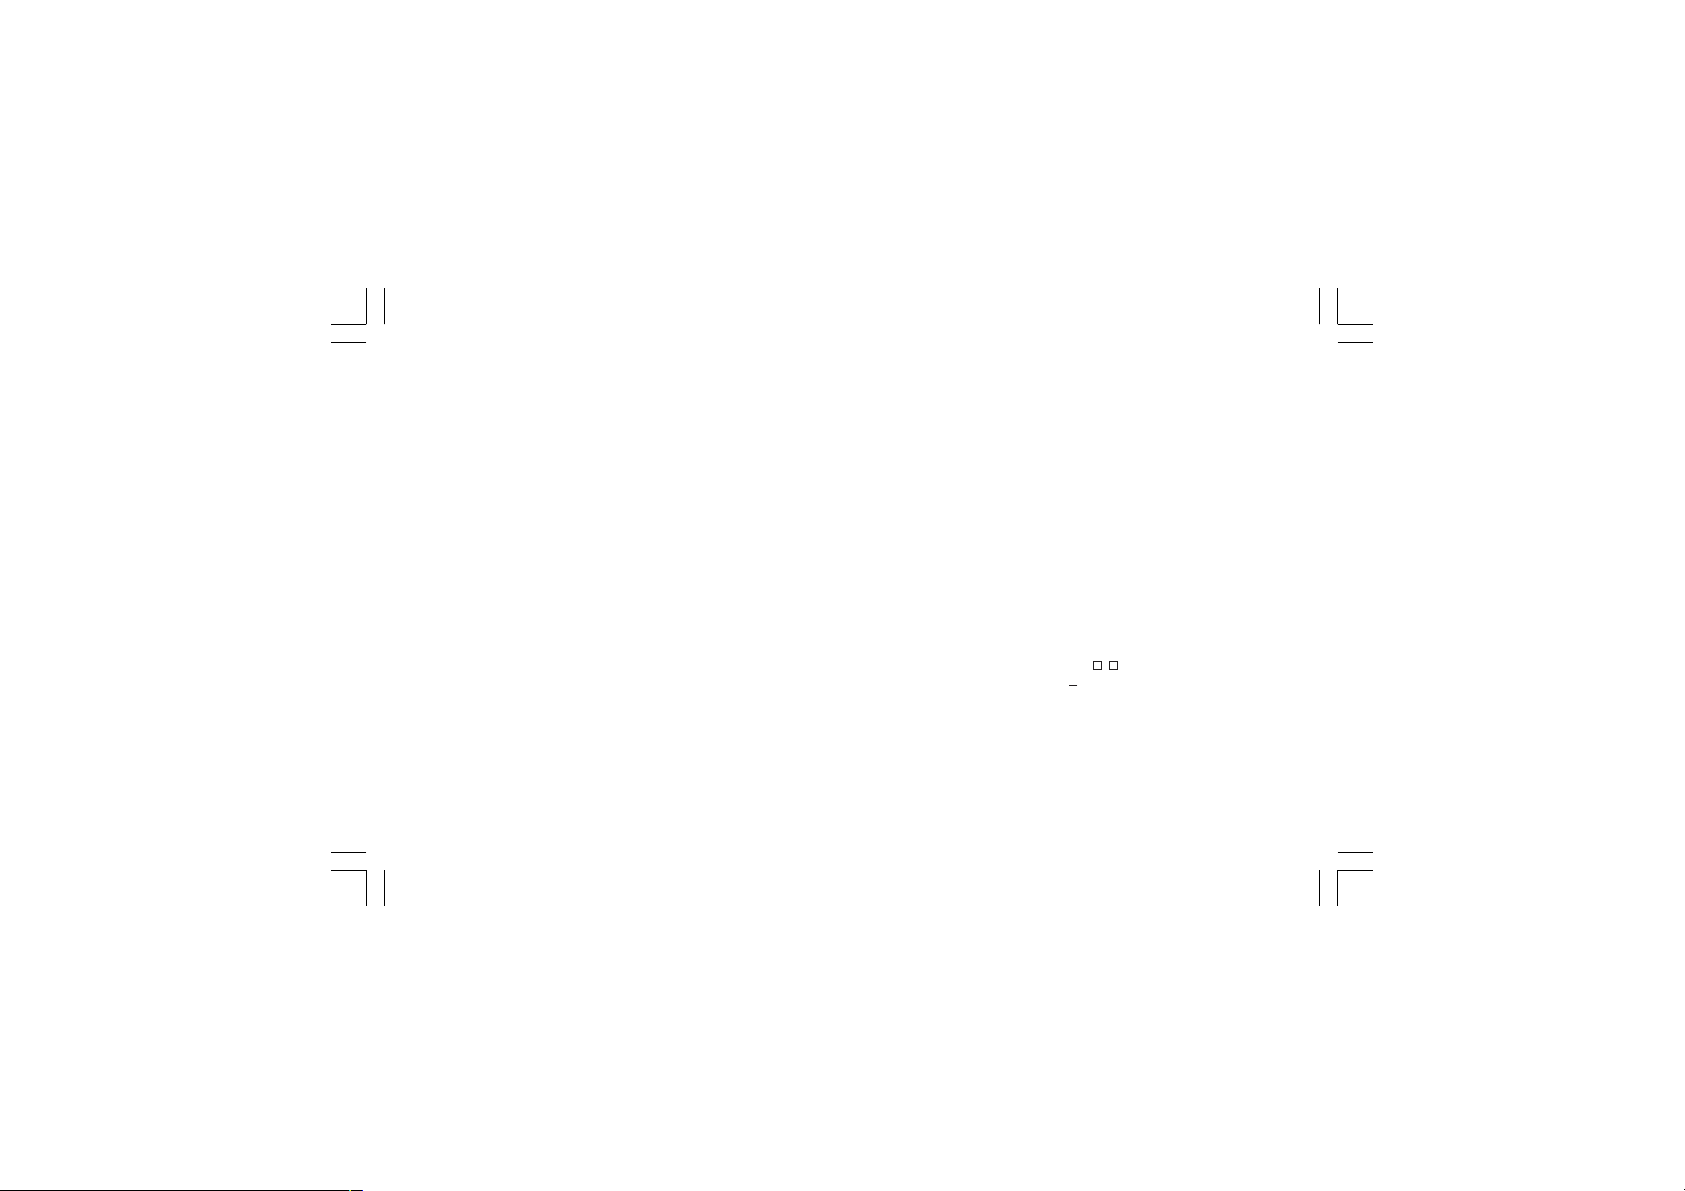
RUN TIME MODE
If V101 is correctly set (see "Operative mode and hardware
lock" at pag. 22), and the configuration mode has been
terminated, the instrument will be in run time mode and in
"normal display mode" (see below).
During run time mode the instrument performs the loop control
and manages all the instrument functions (SMART, ALARMS,
etc.).
DISPLAY FUNCTION
When device is powered and is operating in automatic mode,
the upper display shows the process variable (the value will be
flashing if device is in hold status) and the middle display shows
the set point value (final or operative according to “SP.dS”
[C.I07] parameter setting).
We define the above condition as “normal display mode”.
The lower display will show:
a) at instrument start up, the control output value (the LED % is
lighted).
Xkc-1-C0.P65 5/29/02, 11:59 AM66
NOTES:
In accordance with the configured output type, the control
output can be displayed in the following ways:
a.1) If the device is configured with servomotor control drive
only, the feedback position value is displayed in the
range -19.0 % to 120.0 % (the display is blank if open
loop servomotor without valve position indication has
been programmed)
a.2) If the device is configured with one control output (linear
or time proportional), the control output value is
displayed in the range 0 % to 100 %.
a.3) if the device is configured with two control outputs the
value of the MAIN output is shown on the two most
significant digits while the value of the SECONDARY
output is shown on the two less significant digits.
The decimal point between the two values will be
flashing.
NOTE: the graphic symbol “
“ shows that the
specific control output is > 100%.
Whenever one of the two outputs is a servomotor type,
the instrument shows, for this output, the feedback
position instead of the output in percent.
66
Page 71
b) push the FUNC push-button; the lower display will show " A."
followed by the current consumed by the load under test
when the load is in ON condition (see also "OUT failure
detection").
c) Push FUNC push-button again, the lower display will show "
b." followed by the leakage current running in the load under
test when the load is in OFF condition (see also "OUT failure
detection").
d) Push FUNC push-button again, the lower display will show "
Fd." followed by the OUT failure detection alarm status:
OF = no alarm
AL (flashing) = alarm
AL (steady) = acknowledged alarm
e) Push FUNC push-button again, the lower display will show "
ñ." followed by the MAIN control output value in the range 0.0
% (-19.0 % for feedback) to 99.9 % (“ . “ shows that the
control output is > 100.0 %) or within the scale configured by
“ñC.E.L” [C.F09] and “ñC.E.H” [C.F10].
NOTE: When the MAIN output is a servomotor type, the
instrument shows, for this output, the feedback position
instead of the output in percent.
Xkc-1-C0.P65 5/29/02, 11:59 AM67
f) Push FUNC push-button again, the lower display will show "
S." followed by the SECONDARY control output value in the
range 0.0 % (-19.0 % for feedback) to 99.9 %
(“ . “ shows that the control output is > 100.0 %) or
within the scale configured by “SC.E.L” [C.F15] and “SC.E.H”
[C.F16].
NOTE: When the secondary output is a servomotor type, the
instrument shows, for this output, the feedback position
instead of the output in percent.
g) Push FUNC push-button again, the lower display will show
the value of the auxiliary input, if configured.
- Pushing FUNC push-button again, the display will come back
to the control output value indication.
All the seven types of visualization are not bound to a time out
unless OFD (output failure detection) is in not acknowledged
alarm condition.
In this situation, the instrument forces the indication described at
point d) and, if a different indication is required, it restores this
indication after time out (see “t.out” [C.I10]).
67
Page 72
NOTES:
1) The previous informations will be displayed only if the
relative function has been previously configured.
2) After parameter modification or monitoring, the instrument
comes back to the "normal display mode" with, on the lower
display, the indication previously selected.
INDICATORS
°C Lit when process variable is in Celsius degree.
°F Lit when process variable is in Fahrenheit degree.
ST Flashing when the first step of SMART algorithm is
activated.
Lit when the second step of SMART algorithm is activated.
% Lit when the lower display shows the output power value.
MAN Lit when device is in manual mode.
REM Lit when device is controlled by serial link.
RSP Lit when Remote Set point is used.
SPX Lit when an auxiliary Set point (SP2, SP3 or Sp4) is used.
Flashing when a temporary set point, from serial link, is
used.
Xkc-1-C0.P65 5/29/02, 11:59 AM68
1 Lit when OUT 1 is used as control output and it is in ON
condition or when Event 1 is at logic level 1 or when alarm
1 is in alarm state and acknowledged.
Flashes when alarm 1 is in alarm state and it is not
acknowledged.
2 Lit when OUT 2 is used as control output and it is in ON
condition or when Event 2 is at logic level 1 or when alarm
2 is in alarm state and acknowledged.
Flashes when alarm 2 is in alarm state and it is not
acknowledged.
3 Lit when OUT 3 is used as control output and it is in ON
condition or when servomotor output increases or when
Event 3 is at logic level 1 or when alarm 3 is in alarm state
and acknowledged.
Flashes when alarm 3 is in alarm state and it is not
acknowledged.
4 Lit when OUT 4 is used as control output and it is in ON
condition or when servomotor output decreases or when
Event 4 is at logic level 1 or when alarm 4 is in alarm state
and acknowledged.
Flashes when alarm 4 is in alarm state and it is not
acknowledged.
68
Page 73
BARGRAPH DESCRIPTION
On MKC model only, two 33 LED’s bargraphs are available.
On the right bargraph, with orange LED’s, it is possible to show:
- the operative set point scaled as configured by “brG.L” [C.I03]
and “brG.H” [C.I04].
The “SP” LED, located on the base of the bargraph, is lighted.
- the power output value.
The “%” LED, located on the top of the bargraph, is lit.
When the device has two process outputs, the central LED
(which is a two-color LED) become green. It divides the
bargraph into two parts: the MAIN process output is shown on
the upper part while the SECONDARY process output is
shown on the lower part.
If a process output is a servomotor type, the bargraph will
show the valve position instead of the power output (the first
or last LED’s is flashing when the feedback position is out of
range 0¸100).
On the left bargraph, with green LED’s, it is possible to show:
- the process variable scaled as configured by “brG.L” [C.I03]
Xkc-1-C0.P65 5/29/02, 11:59 AM69
and “brG.H” [C.I04].
The “PV” LED, located on the base of the bargraph, is lit.
- The deviation error (PV - SP) with resolution configured at
“brG.d” [C.I05].
The “DEV” LED, located on the top of the bargraph, is lit.
When the deviation error indication is selected, the central
LED (which is a two-color LED) become orange. It devides
the bargraph is two parts: the positive error is shown on the
upper part while the negative error is shown on the lower part.
The last LED will flash if deviation is out of range.
69
Page 74
OUT FAILURE DETECTION FUNCTION (OFD)
The device is capable to measure and display:
- the current running in a load driven by a time proportional
control output (main or secondary programmable) when the
load is energized;
- the leakage current flowing through the load when the load is
de-energized.
If the instrument has been correctly set, it generates an alarm
when:
- the current running in the load (when the load is energized) is
lower than the "A.L.Fd" [r.C14] parameter value (It shows a
partial or total break down of the load, the break down of the
actuator or a power down due to a protection or a fuse
intervention);
- the leakage current (when the load is de-energized) is higher
than the "A.H.Fd" [r.C15] parameter value (It shows a short
circuit of the actuator).
The "Display function" paragraph describes how to show the two
current values.
The fault condition is shown on the lower display by the "Fd.AL"
indication ("AL" may be flashing or steady on in accordance with
acknowledge condition) and by the status of the assigned
output.
If the ON or OFF period is lower than 120 ms the relative
measurement couldn't be performed and the instrument will
show flashing the last measured value.
Xkc-1-C0.P65 5/29/02, 11:59 AM70
DIRECT ACCESS TO THE SET POINT
When the device is in AUTO mode and in “Normal Display
Mode”, it is possible to access directly to the selected set point
modification (SP, SP2, SP3 or SP4).
Pushing s or t for more than 2 s, the set point will begin
changing.
The new set point value becomes operative since no pushbutton has been depressed at the end of 2 s time out.
The direct access to the set point is disabled if the run time
group 1 is software protected or remote set point is used.
70
Page 75
MANUAL FUNCTION
The MANUAL mode function can be accessed (only if
configured) by depressing the MAN push-button for more than 1
sec or by acting on a logic input configured as "Au.ñA" (auto/
manual selection).
The command from keyboard is accepted and executed only if
the instrument is in "Normal Display Mode" while the command
from logic input is always accepted.
When in MANUAL mode the LED's MAN light up while the
middle display shows "ñ." followed by the main output values
(from 0.0 to 99.9%) and the lower display shows "S." followed by
the secondary output value (from 0.0 to 99.9%).
When the device is configured with one control output only and
this output is “Servo”, the display will show the current valve
position.
When the device has two control outputs and one of them is
“Servo”, during valve positioning the display will show the final
position of the valve and not the current position.
The control output and/or the feedback position can be modified
by using “s”and “t”.
Xkc-1-C0.P65 5/29/02, 11:59 AM71
To come back to the AUTO mode, depress “MAN” push-button
for more then 1 sec. or toggle the logic input.
The transfer from AUTO to MANUAL is bumpless (this function
is not provided if an output value has been selected at
configuration parameter “Añ.UL” [C.G04]).
The transfer from MANUAL to AUTO is bumpless or bumpless
balanceless (the bumpless feature is not provided if integral
action is excluded).
If transfer from AUTO to MANUAL is performed during the first
part of SMART algorithm (TUNE) when returning in AUTO the
device will be forced automatically in the second part of the
SMART algorithm (ADAPTIVE).
At power up the device starts as configured at “St.Fn” [C.G06]
configuration parameter.
NOTES:
1) When auto/manual control mode is selected by logic input, at
power up the instrument will start in accordance with the logic
input status.
If the logic input status requires the manual mode, the
instrument will verify the “St.Fn” [C.G06] parameter setting
and if “St.Fn” [C.G06] is equal to "Auto", "ñan" or “Cnd.A” the
power output will be set to zero otherwise the power output
will be set equal to the last value prior to power shut down.
71
Page 76
2) If the instrument is configured for one control output, the
control output is a servo motor type (close or open loop) and
device starts up in manual mode, the following action may
occur:
2.A) The valve remains in the same position if:
“St.Fn” [C.G06] = “ñan” or
“St.Fn” [C.G06] = “Cnd.A” or
“St.Fn” [C.G06] = “Cnd.b” and “Añ.UL” [C.G04] = “buñ.”
2.B) The valve will be moved to the value set in “Añ.UL” if
“St.Fn” [C.G06] = “Cnd.b” and “Añ.UL” [C.G04] is
different from “buñ.”
Xkc-1-C0.P65 5/29/02, 11:59 AM72
SERIAL LINK
The device can be connected to a host computer by a serial link.
The host can put the device in LOCAL (functions and parameters are controlled via keyboard) or in REMOTE (functions and
parameters are controlled via serial link).
The REMOTE status is signalled by the REM LED.
This instrument allows to modify the operative and configuration
parameters, via serial link.
The necessary conditions to implement this function are the
following:
1) the serial parameters (see Run time group 7) should be
properly configured.
2) the device must be in the run time mode.
3) when it is desired to modify configuration parameter, the dip
switch V101.3 should be set to "OFF" (configuration
parameter enabled)
During configuration parameter downloading the device goes in
open loop with all output in OFF state.
At the end of configuration procedure, the device performs an
automatic reset and then returns to close loop control.
72
Page 77
LAMP TEST
When it is desired to verify the display efficiency, put the
instrument in "normal display mode" and push t and MENU
push-buttons for more than 5 s.
The instrument will turn ON, with a 50 % duty cycle, all the LEDs
of the display (we define this function "LAMP TEST").
No time out is applied to the LAMP TEST.
When it is desired to come back to the normal display mode,
push any push-button.
During the LAMP TEST the instrument continues to control the
process.
SMART FUNCTION
It is used to automatically optimize the control action.
To enable the SMART function proceed as follows:
1) push the MENU push-button until "Gr. 2" run time parameter
group is shown.
2) push the FUNC push-button until "Sñrt" parameter is shown.
3) push s or t and set the "On" indication on the middle
display;
4) push the FUNC push-button.
Xkc-1-C0.P65 5/29/02, 11:59 AM73
The ST LED will turn on or flashing according to the selected
algorithm.
When the smart function is enabled, it is possible to display but not
to modify the control parameters.
To disable the SMART function proceed as follows:
1) push the MENU push-button until "Gr. 2" run time parameter
group is shown.
2) push the FUNC push-button until "Sñrt" parameter is shown.
3) push s or t and set the "OFF" indication on the middle
display;
4) push the FUNC push-button.
The ST LED will turn off.
The instrument maintains the current set of control parameters
and it enables parameter modification.
NOTES : 1) When ON/OFF control is programmed (Pb=0), the
SMART function is disabled.
2) The SMART enabling/disabling can be protected
by safety key.
73
Page 78
HOLD FUNCTION
By means of an logic input it is possible to stop the inputs
sampling keeping frozen the last measure values (main and
auxiliary input).
During measuring hold the instrument will continue to control the
process using the last measured values and the following
functions will be inhibited:
1) Local set point to remote set point transfer and viceversa
2) Manual to auto mode transfer
NOTE: The auto to manual transfer is allowed
The measure value on the upper display will be flash to indicate
the hold status
PARAMETER PROTECTION
Moving from one run time parameter group to another, the
instrument will show, at first, the group number (on the upper
display), the mnemonic code (on the lower display) and the
security status (on the middle display) of the group.
Xkc-1-C0.P65 5/29/02, 11:59 AM74
The possible security status are:
Enb = the parameters of this group are not protected and they
may be modified;
inh = the parameters of this group are ever protected and
they cannot be modified
- - - - = the parameters of this group are software protected.
In this case, using “s“ and “t” push-button set a value
equal to the security code programmed during the "Run
time security code " (see page 23) and then push
“FUNC”.
If the programmed value matches the security code the
parameters of this group can be modified otherwise they
remain protected.
ATTENTION: One software key protects one or more run time
parameter groups so that when the software key is inserted, it is
possible to modify the run time parameters of all groups.
The software protection will be automatically restored when the
instrument comes back to the "normal display mode" (by
"MENU" push-button pressure or by the time out).
74
Page 79
RUN TIME PARAMETER MODIFICATION.
By “MENU” push-button it is possible to start the run time
parameter modification by selecting desired run time parameter
group.
During the run time parameter modification, the upper display
shows the selected parameter group, the lower display shows
the mnemonic code of the selected parameter while the central
display shows the value or status assigned to the selected
parameter.
The parameter monitoring and modification are subjected to a
time out (see “t.out” [C.I10] parameter) after that the display
returns in “Normal display mode” and the eventual modification
on the last displayed parameter will be lost.
NOTES:
1) In the following pages we will describe all the parameter of
the instrument but it will show only the parameters related
with the specific hardware and in accordance with the specific
instrument configuration.
2) If all the parameters of a group are not available, the
instrument will not display this group.
3) For an easy consultation of the manual, it is accompanied by
a table with all the run time parameter visualization.
Xkc-1-C0.P65 5/29/02, 11:59 AM75
Run time group 1 [r.Axx]
Set point VALUES
Gr.1
- Main set point - [r.A01]
Range: from "rL" [r.E12] to "rH" [r.E13].
- Set point 2 - [r.A02]
This parameter is available only when one of the logic inputs is
configured for SP/SP2 selection
Range: from "rL" [r.E12] to "rH" [r.E13].
75
Page 80
- Set point 3 - [r.A03]
This parameter is available only when one of the logic inputs is
configured for SP3/SP4 selection.
Range: from "rL" [r.E12] to "rH" [r.E13].
Run time group 2 [r.bxx]
SMART ENABLE/DISABLE
Gr.2
- Set point 4 - [r.A04]
This parameter is available only when one of the logic inputs is
configured for SP/SP2 selection and another one for SP3/SP4
selection.
Range: from "rL" [r.E12] to "rH" [r.E13].
- Group 1 default data loading - [r.A05]
Range: OFF = No loading data
ON = Loading data
Xkc-1-C0.P65 5/29/02, 11:59 AM76
- SMART function - [r.b01]
This parameter is available when at least one control output is
configured and SMART function is enabled (“Sñ.Fn” [C.G01]=
“Enb”)
Range: OFF = SMART algorithm is deactivated
ON = SMART algorithm is activated
Set On or OFF to activate/deactivate the SMART algorithm.
76
Page 81
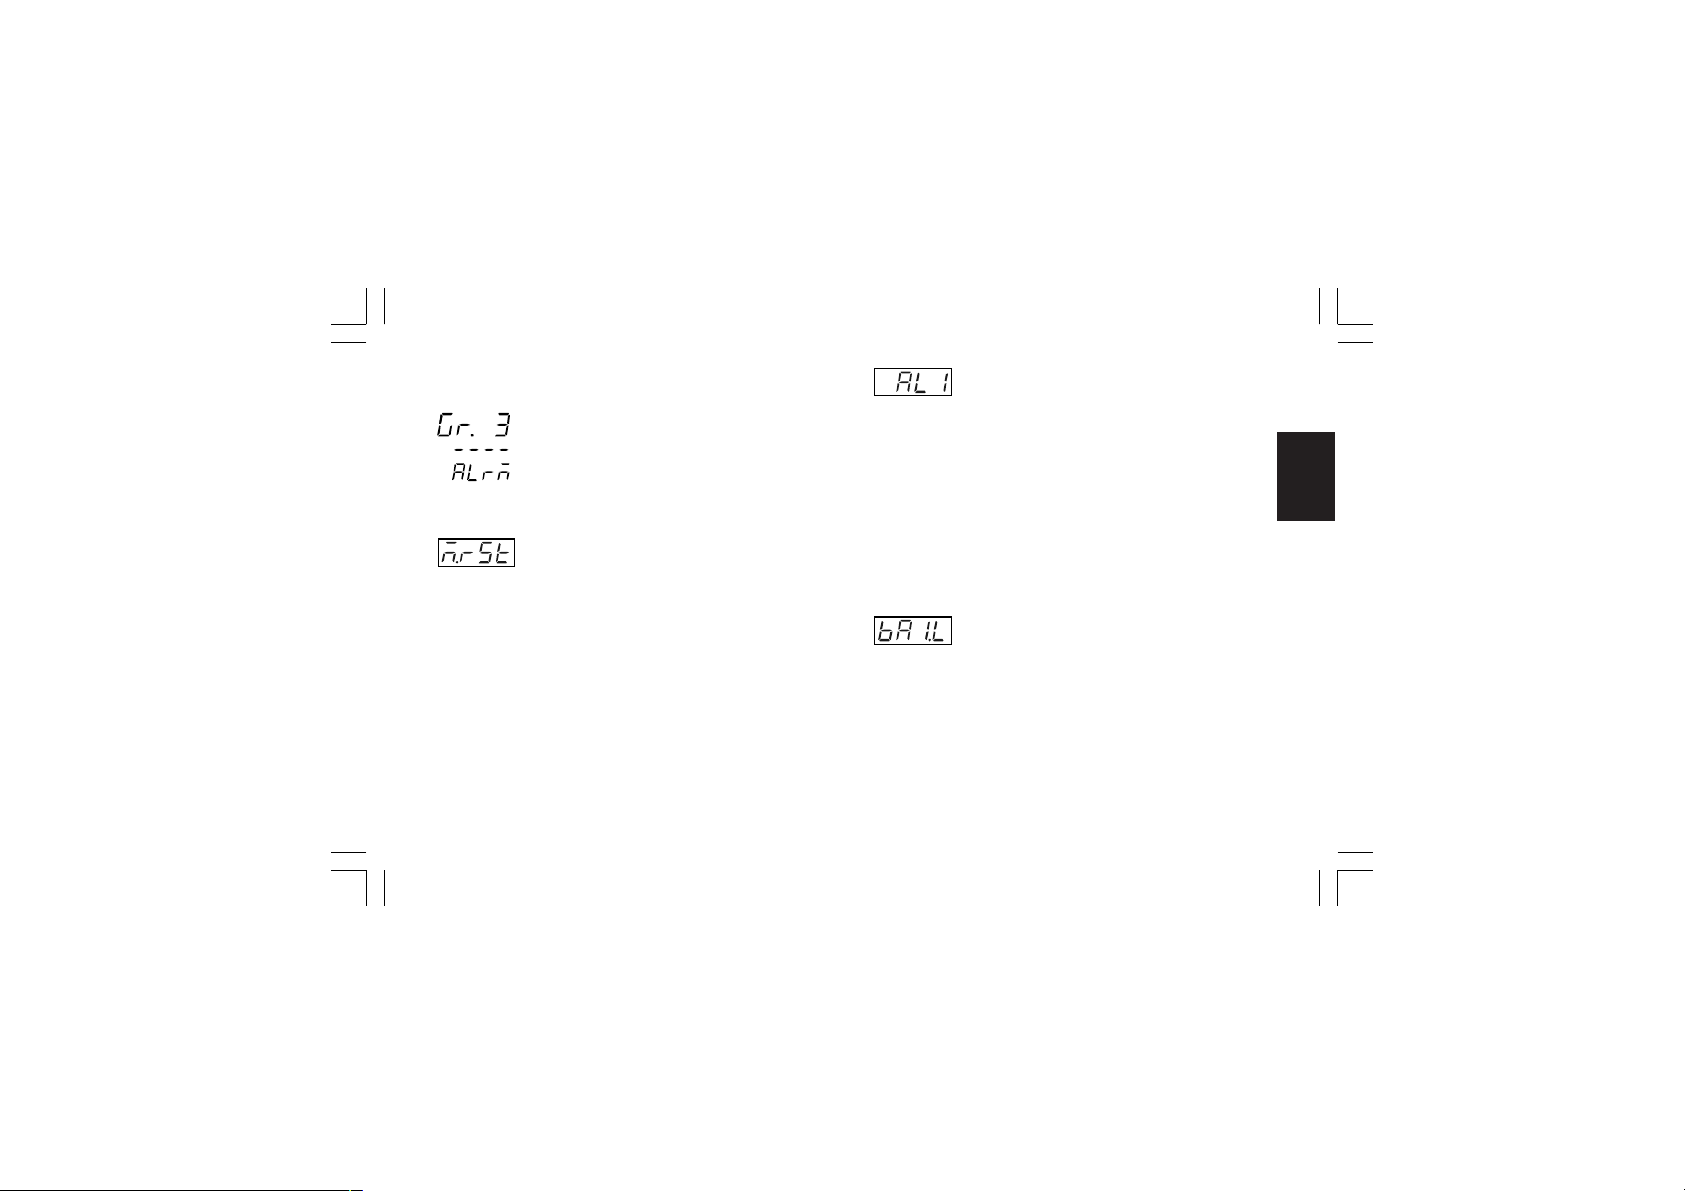
Run time group 3 [r.Cxx]
ALARM THRESHOLD AND HYSTERESIS VALUE
- Manual reset of the alarms - [r.C01]
Range: ON/OFF
Change to ON and then depress “FUNC” key to reset/
acknowledge the alarm condition.
NOTES:
1) The reset/acknowledge function is always enabled.
2) When one of the logic input is configured as alarm reset, both
actions (of "ñ.rSt" parameter and of the logic input) are active.
Xkc-1-C0.P65 5/29/02, 11:59 AM77
- Alarm 1 threshold - [r.C02]
This parameter is available when alarm 1 is configured as
process, deviation, main power output or secondary power
output alarm (“A1.tP” [rF.01] = “Proc” or “dEV” or “ñAin” or
“SECn”)
Range: - in engineering units within the span limits for process
alarm;
- from -1000 to 1000 digits for deviation alarm;
- from 0.0% to 100.0 % for control output alarm.
NOTE: The span limits are configured by “ñ.In.L” [C.d05] and
“ñ.In.H” [C.d06].
- Low threshold used when the alarm 1 is a
band alarm - [r.C03]
This parameter is available only when the alarm 1 is configured
as band alarm (“A1.tP” [rF.01] = “bAnd”)
Range: from 0 to -1000 digits.
77
Gr.3
Page 82
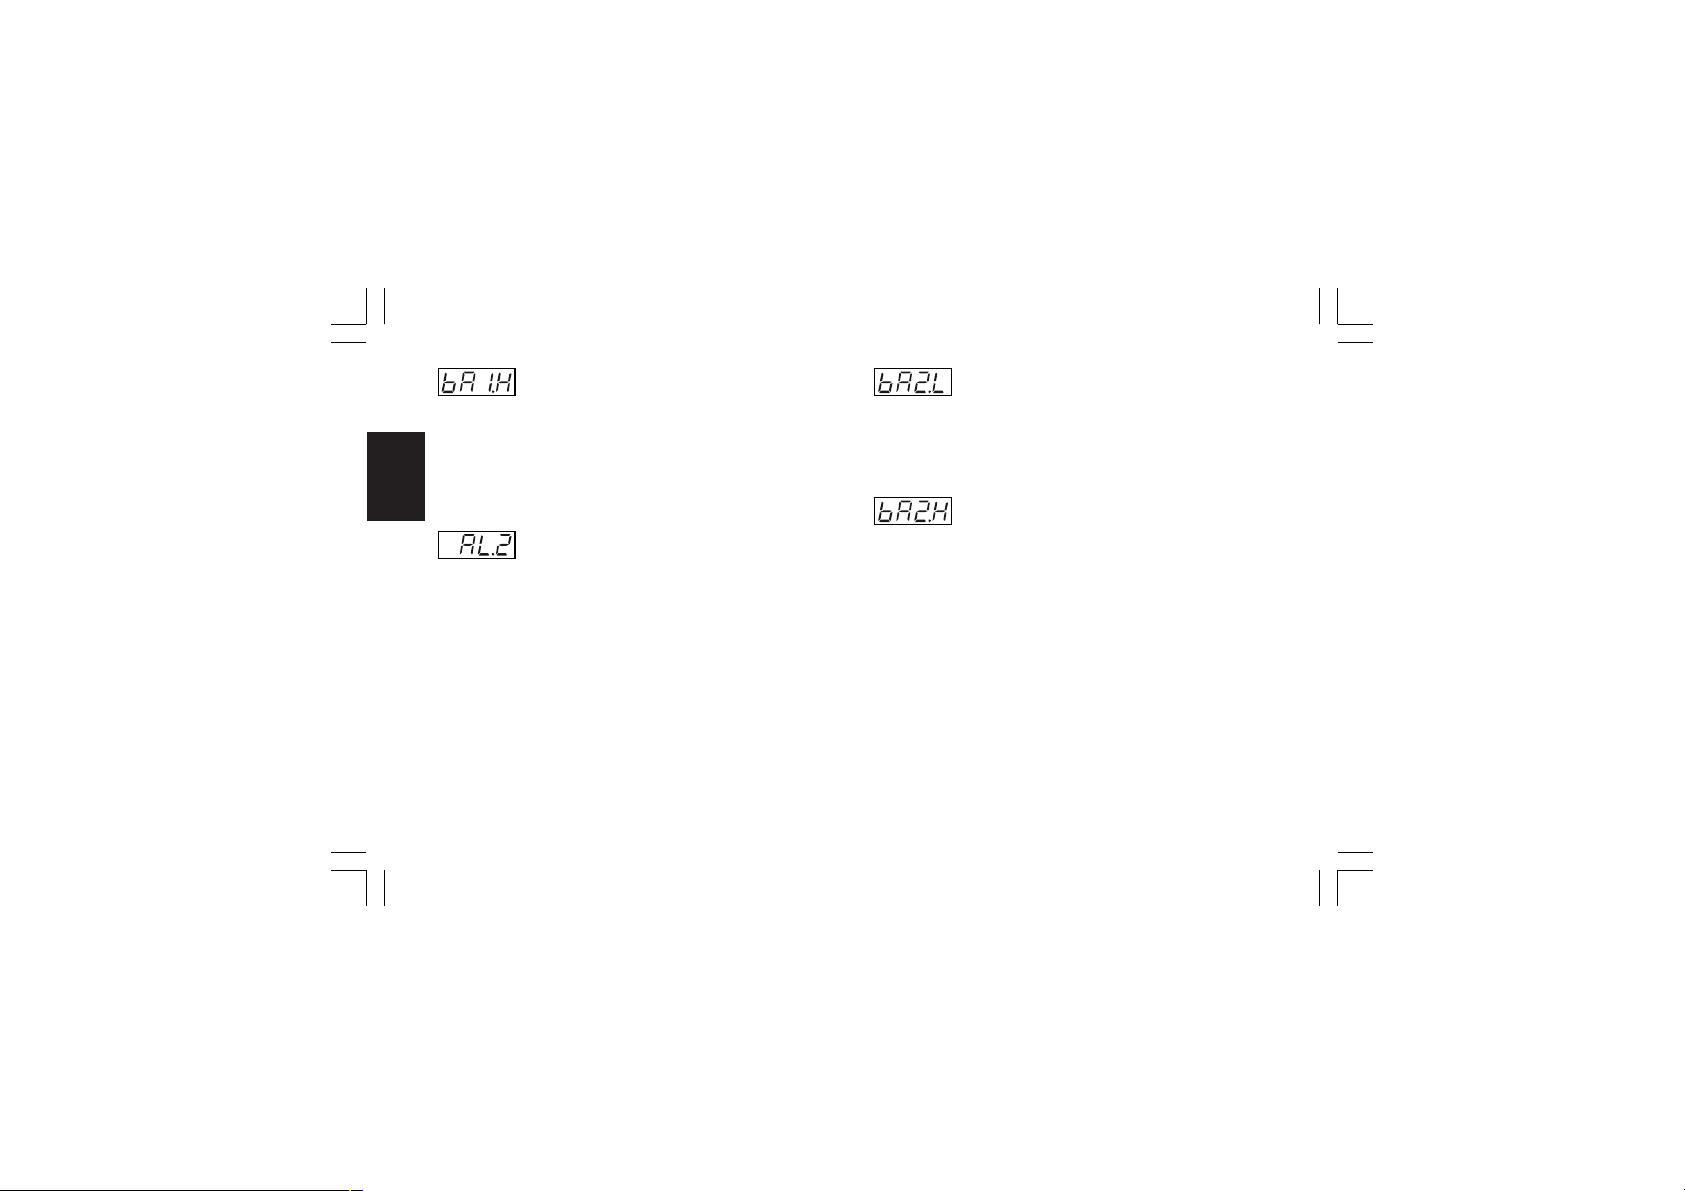
- high threshold used when the alarm 1 is a
band alarm - [r.C04]
This parameter is available only when the alarm 1 is configured
as band alarm (“A1.tP” [rF.01] = “bAnd”)
Range: from 0 to 1000 digits.
NOTE: The "bA1.L" and "bA1.h" values are algebraically added
to the operative set point in order to obtain the band limits.
Gr.3
- Alarm 2 threshold - [r.C05]
This parameter is available when alarm 2 is configured as
process, deviation, main power output or secondary power
output alarm (“A2.tP” [rF.05] = “Proc” or “dEV” or “ñAin” or
“SECn”)
Range: - in engineering units within the span limits for process
alarm;
- from -1000 to 1000 digits for deviation alarm;
- from 0.0% to 100.0 % for control output alarms.
NOTE: The span limits are configured by “ñ.In.L” [C.d05] and
“ñ.In.H” [C.d06].
Xkc-1-C0.P65 5/29/02, 11:59 AM78
- Low threshold used when the alarm 2 is a
band alarm - [r.C06]
This parameter is available only when the alarm 2 is configured
as band alarm (“A2.tP” [rF.05] = “bAnd”)
Range: from 0 to -1000 digits.
- high threshold used when the alarm 2 is a
band alarm - [r.C07]
This parameter is available only when the alarm 2 is configured
as band alarm (“A2.tP” [rF.05] = “bAnd”)
Range: from 0 to 1000 digits.
NOTE: The "bA2.L" and "bA2.h" values are algebraically added
to the operative set point in order to obtain the band limits.
78
Page 83
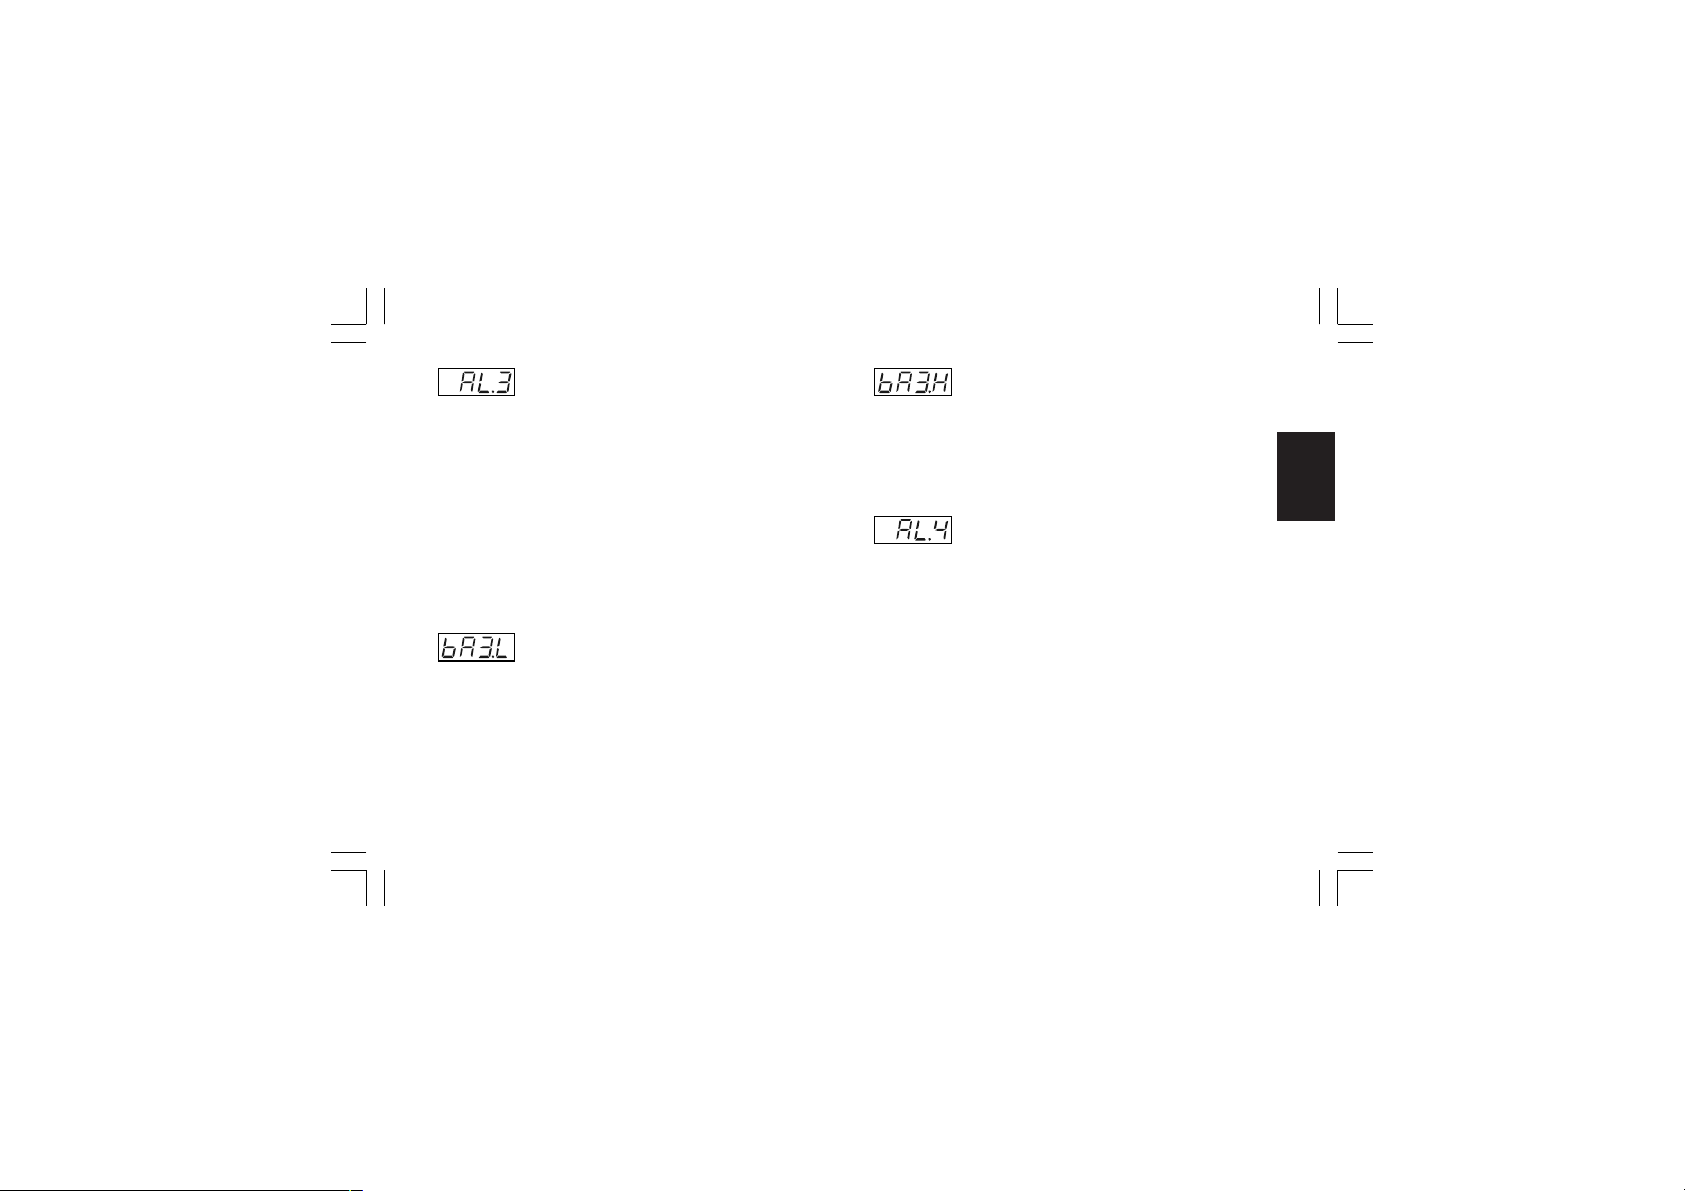
- Alarm 3 threshold - [r.C08]
This parameter is available when alarm 3 is configured as
process, deviation, main power output or secondary power
output alarm (“A3.tP” [rF.09] = “Proc” or “dEV” or “ñAin” or
“SECn”)
Range: - in engineering units within the span limits for process
alarm;
- from -1000 to 1000 digits for deviation alarm;
- from 0.0% to 100.0 % for control output alarms.
NOTE: The span limits are configured by “ñ.In.L” [C.d05] and
“ñ.In.H” [C.d06].
- Low threshold used when the alarm 3 is a
band alarm - [r.C09]
This parameter is available only when the alarm 3 is configured
as band alarm (“A3.tP” [rF.09] = “bAnd”)
Range: from 0 to -1000 digits.
Xkc-1-C0.P65 5/29/02, 11:59 AM79
- high threshold used when the alarm 3 is a
band alarm - [r.C10]
This parameter is available only when the alarm 3 is configured
as band alarm (“A3.tP” [rF.09] = “bAnd”)
Range: from 0 to 1000 digits.
NOTE: The "bA3.L" and "bA3.h" values are algebraically added
to the operative set point in order to obtain the band limits.
- Alarm 4 threshold - [r.C11]
This parameter is available when alarm 4 is configured as
process, deviation, main power output or secondary power
output alarm (“A4.tP” [rF.13] = “Proc” or “dEV” or “ñAin” or
“SECn”)
Range: - in engineering units within the span limits for process
alarm;
- from -1000 to 1000 digits for deviation alarm;
- from 0.0% to 100.0 % for control output alarms.
NOTE: The span limits are configured by “ñ.In.L” [C.d05] and
“ñ.In.H” [C.d06].
79
Gr.3
Page 84
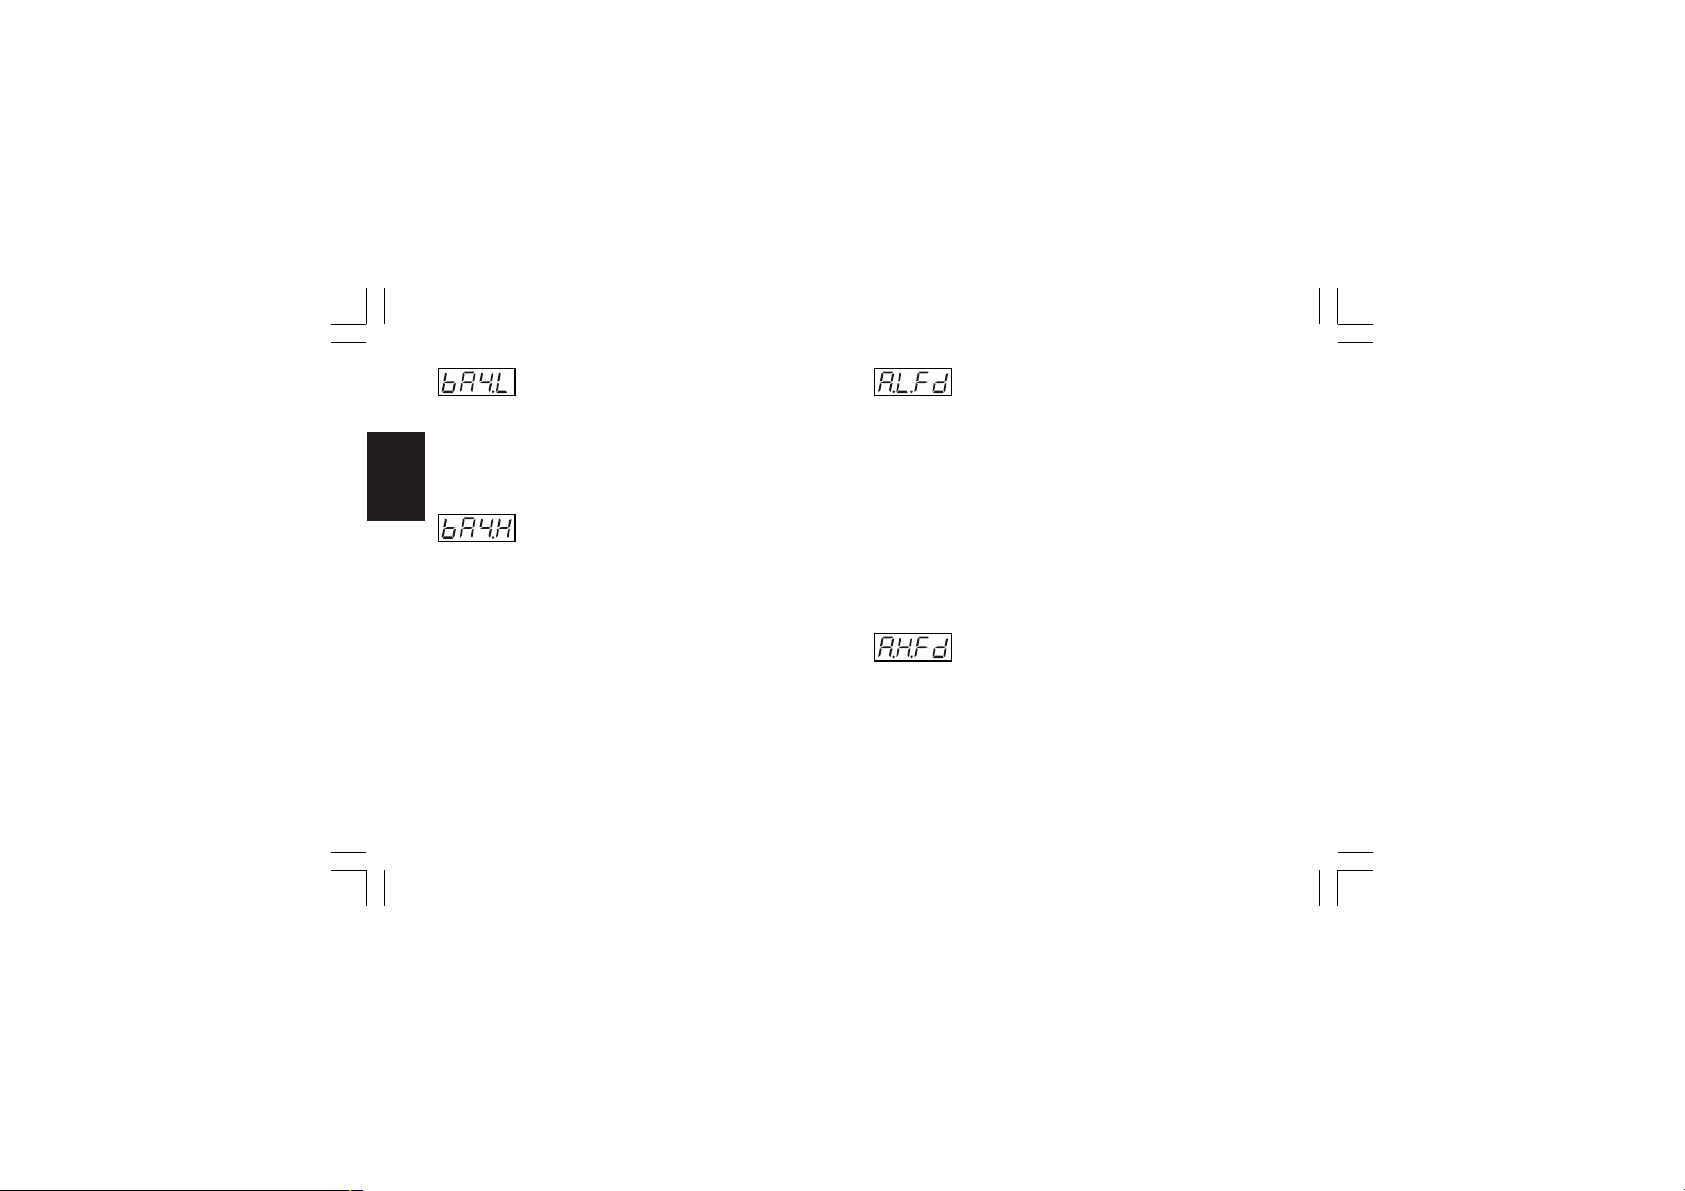
- Low threshold used when the alarm 4 is a
band alarm - [r.C12]
This parameter is available only when the alarm 4 is configured
as band alarm (“A4.tP” [rF.13] = “bAnd”)
Range: from 0 to -1000 digits.
Gr.3
- high threshold used when the alarm 4 is a
band alarm - [r.C13]
This parameter is available only when the alarm 4 is configured
as band alarm (“A4.tP” [rF.13] = “bAnd”)
Range: from 0 to 1000 digits.
NOTE: The "bA4.L" and "bA4.h" values are algebraically added
to the operative set point in order to obtain the band limits.
Xkc-1-C0.P65 5/29/02, 11:59 AM80
- Output failure detection low alarm threshold [r.C14]
This parameter is available only when the option is present and
“Fd.Fn” [C.I10] is equal to “ñC.On” or “ñC.OF” or “SC.On” or
“SC.OF”.
Range: from 0 to "Fd.HS" [C.I12].
NOTES:
1) The device is in alarm status when the current, measured
during the ON status of the load, is lower than this threshold.
2) The OFD (output failure detection) alarm threshold resolution
values is equal to 0.1 A for range up to 25 A and 1 A for
range up to 100 A
3) The hysteresis on this threshold values is fixed to 1% of fsv
- Output failure detection high alarm threshold
- [r.C15]
This parameter is available only when the option is present and
“Fd.Fn” [C.I10] is equal to “ñC.On” or “ñC.OF” or “SC.On” or
“SC.OF”.
Range: from 0 to "Fd.HS" [C.I12].
NOTES:
1) The device is in alarm status when the current, measured
during the OFF status of the load (leakage current), is higher
than this threshold.
80
Page 85
2) The OFD (output failure detection) alarm threshold resolution
values is equal to 0.1 A for range up to 25 A and 1 A for
range up to 100 A
3) The hysteresis on this threshold values is fixed to 1% of fsv
- Alarm 3 hysteresis - [r.C18]
This parameter is available only when Out 3 is configured as
alarm output (“O3.Fn” [C.E03] = “ALr.3”)
Range: from 1 to 200 digits
- Alarm 1 hysteresis - [r.C16]
This parameter is available only when Out 1 is configured as
alarm output (“O1.Fn” [C.E01] = “ALr.1”)
Range: from 1 to 200 digits
- Alarm 2 hysteresis - [r.C17]
This parameter is available only when Out 2 is configured as
alarm output (“O2.Fn” [C.E02] = “ALr.2”)
Range: from 1 to 200 digits
Xkc-1-C0.P65 5/29/02, 11:59 AM81
- Alarm 4 hysteresis - [r.C19]
This parameter is available only when Out 4 is configured as
alarm output (“O4.Fn” [C.E04] = “ALr.4”)
Range: from 1 to 200 digits
- Group 3 default data loading - [r.C20]
Range: OFF = No loading data
ON = Loading data
81
Gr.3
Page 86
Run time group 4 [r.dxx]
CONTROL PARAMETERS
- Hysteresis (for ON/OFF control) - [r.d02]
This parameter is available when Pb [r.d01]=0 (On/OFF control
action)
Range: from 0.1% to 10.0% of the input span.
Gr.4
NOTE: when SMART function is activated, all the parameters
calculated by SMART (Pb, Ti, Td and rCG) can not be modified.
- Proportional band - [r.d01]
This parameter is available when at least one control output is
configured.
Range: from 0.5% to 999.0% of the input span.
Set 0.0% for On/OFF control action
NOTES:
1) The Pb resolution will be equal to 0.1% up to 10.0% and 1%
up to 999.0.
2) When device is working with SMART algorithm the “Pb” value
will be limited as selected by parameters “Pb.Hi” [r.L02] and
“Pb.Lo” [r.L01]
Xkc-1-C0.P65 5/29/02, 11:59 AM82
- Integral time - [r.d03]
This parameter is available when at least one control output is
configured and Pb [r.d01] is different from 0.
Range: from 00.01 to 20.00 mm.ss
Above this value the display blanks and the integral
action is excluded
NOTE: When device is working with SMART algorithm the “ti”
value will be limited as selected by “ti.Hi” [r.L04] and “ti.Lo”
[r.L03].
82
Page 87
- Derivative time - [r.d04]
This parameter is available when at least one control output is
configured, “Cn.tP” [C.G02] is equal to “Pid” and "Pb" [r.d01] is
different from 0.
Range: From 00.00 to 10.00 mm.ss
NOTES:
1) When device is working with SMART algorithm and “Cn.tP”
[C.G02] is equal to “Pid”, the “td” value will be made equal to
a quarter of “ti” value.
2) When “Cn.tP” [C.G02] is equal to “Pi”, the derivative action is
excluded
- Integral preload - [r.d05]
This parameter is available when at least one control output is
configured and "Pb" [r.d01] is different from 0.
Ranges:
- from 0.0 to 100.0 % of the output when device is configured
with only one control output
- from -100.0 to 100.0 % of the output when device is
configured with two control outputs (split range excluded)
Xkc-1-C0.P65 5/29/02, 11:59 AM83
- Relative secondary output gain - [r.d06]
This parameter is available when two control outputs are
configured (split range excluded) and "Pb" [r.d01] is different
from 0.
Range: from 0.20 to 2.00
- Overlap/dead band between main and
secondary outputs - [r.d07]
This parameter is available when two control outputs are
configured (split range excluded) and "Pb" [r.d01] is different
from 0.
Range: from -20 to 50
NOTE: A negative value means a dead band while a positive
value means an overlap.
- Control action - [r.d08]
Range: rEv = reverse action
dir = direct action
83
Gr.4
Page 88
REVERSE ACTION DIRECT ACTION
Input
Input
t
Output
Output
Run time group 5 [r.Exx]
AUXILIARY CONTROL PARAMETER
t
Gr.5
t
NOTES:
1) When device is configured with two control outputs (split
range excluded) the control action is forced to reverse and it
cannot be modify.
2) When direct/reverse selection is performed by a logic input
this parameter allows you to monitor the current selected
action only.
- Group 4 default data loading - [r.d09]
Range: OFF = No loading data
ON = Loading data
Xkc-1-C0.P65 5/29/02, 11:59 AM84
t
- Anti reset wind up - [r.E01]
This parameter is available when at least one control output is
configured and "Pb" [r.d01] is different from 0.
Range: from 10% to 200% of the input span
- Servo motor travel time - [r.E02]
This parameter is available when the open loop servomotor
control drive output is configured (“O3.Fn” [C.E03] is equal to
“ñC.Sñ” or “SC.Sñ” and “Sñ.tP” [C.E05] are equal to “OPEn”).
Range: from 0.12 to 3.00 m.ss
84
Page 89
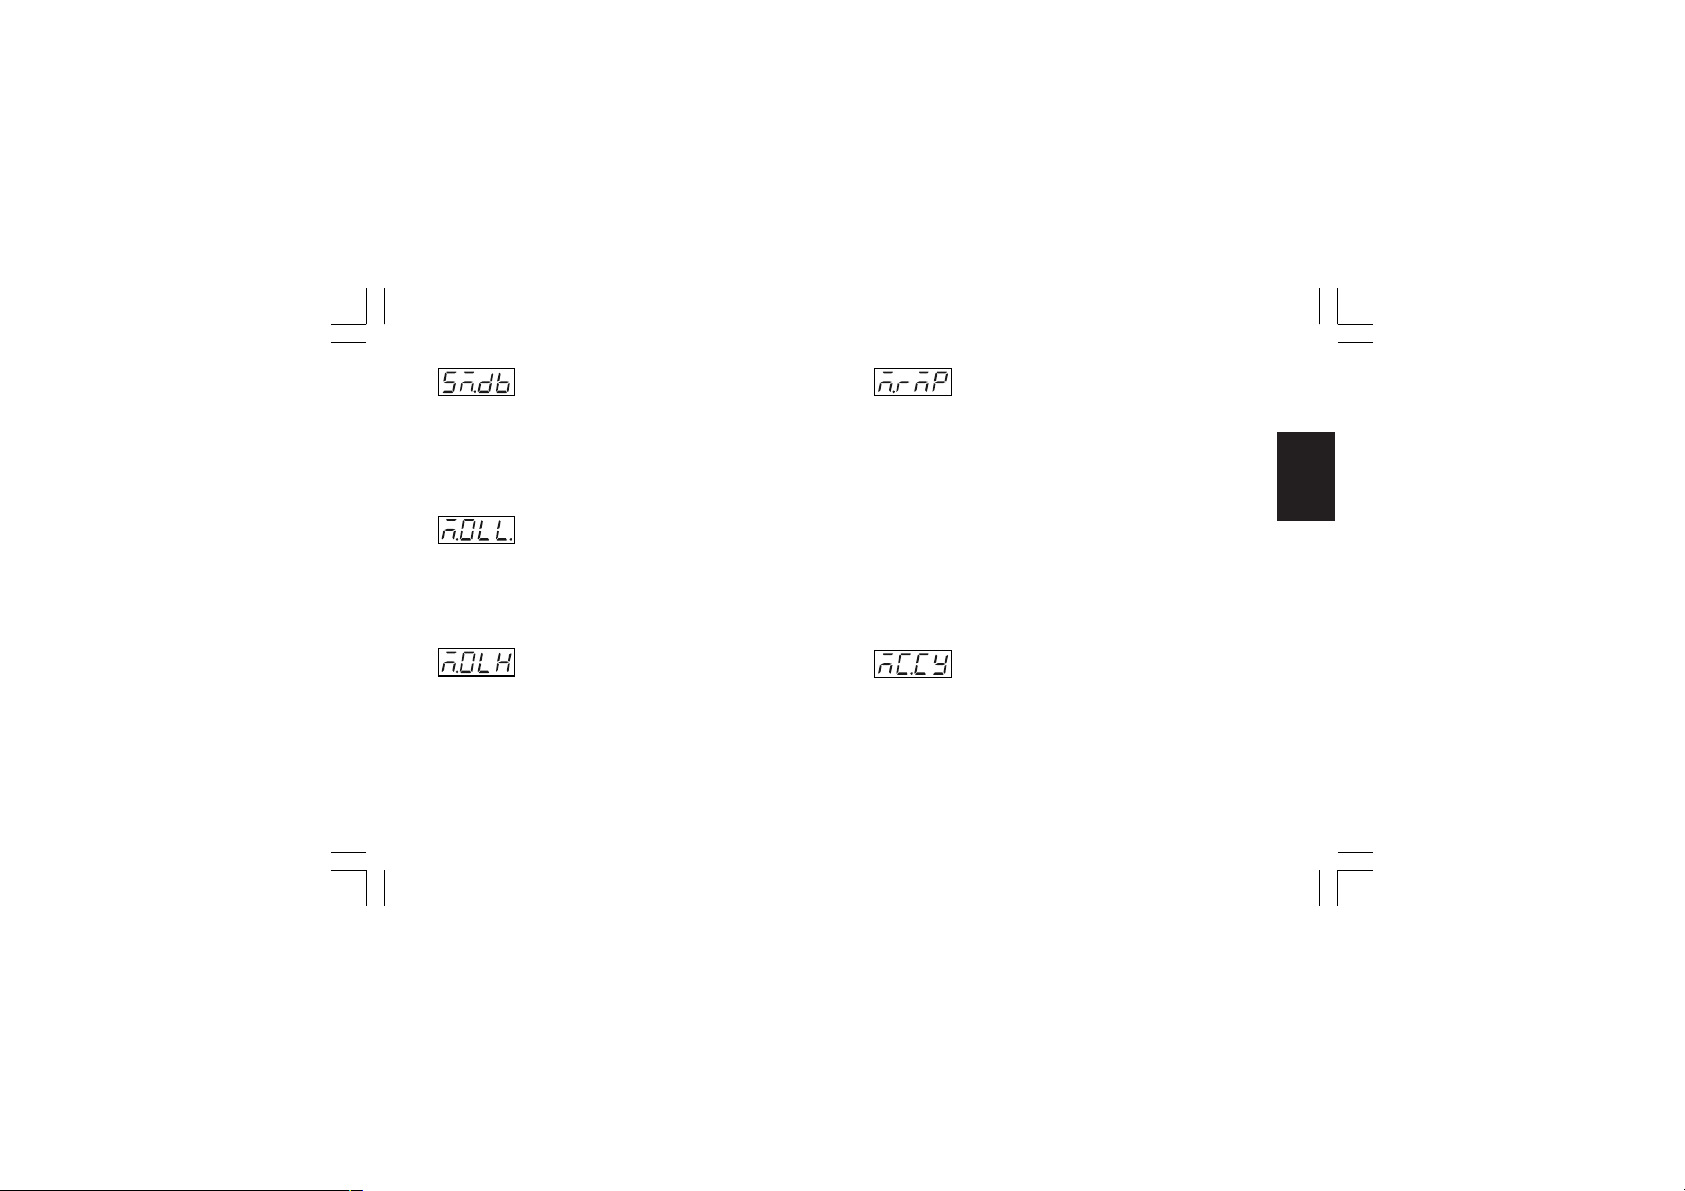
- Servo motor dead band - [r.E03]
This parameter is available when the servomotor control drive
output is configured (“O3.Fn” [C.E03] is equal to “ñC.Sñ” or
“SC.Sñ” ).
Range: from 1% to 50%
- Main control output low limit - [r.E04]
This parameter is available when one control output is
configured as main output.
Range: from 0.0 % (of the output span) to ñ.OLH [r.E05]
- Main control output max rate of rise - [r.E06]
This parameter is available when one control output is
configured as main output.
Ranges: from 0.1%/s to 25.0%/s.
Above this value the display shows “Inf” meaning that no limit is
imposed
NOTES:
1) This parameter will be active even if device is configured for
On/OFF control.
2) During the transfert from AUTO to MANUAL, if this action is
programmed as a not bumpless transfer, the “ñ.rñP” function
will be ignored and the output will step up to the value set by
“Añ.UL” [C.G04] parameter.
Gr.5
- Main control output high limit - [r.E05]
This parameter is available when one control output is
configured as main output.
Range: from ñ.OLL [r.E04] to 100.0 % of the output span
Xkc-1-C0.P65 5/29/02, 11:59 AM85
- Main output cycle time - [r.E07]
This parameter is available when time proportional main control
output is configured.
Range: from 1 to 200 s
85
Page 90
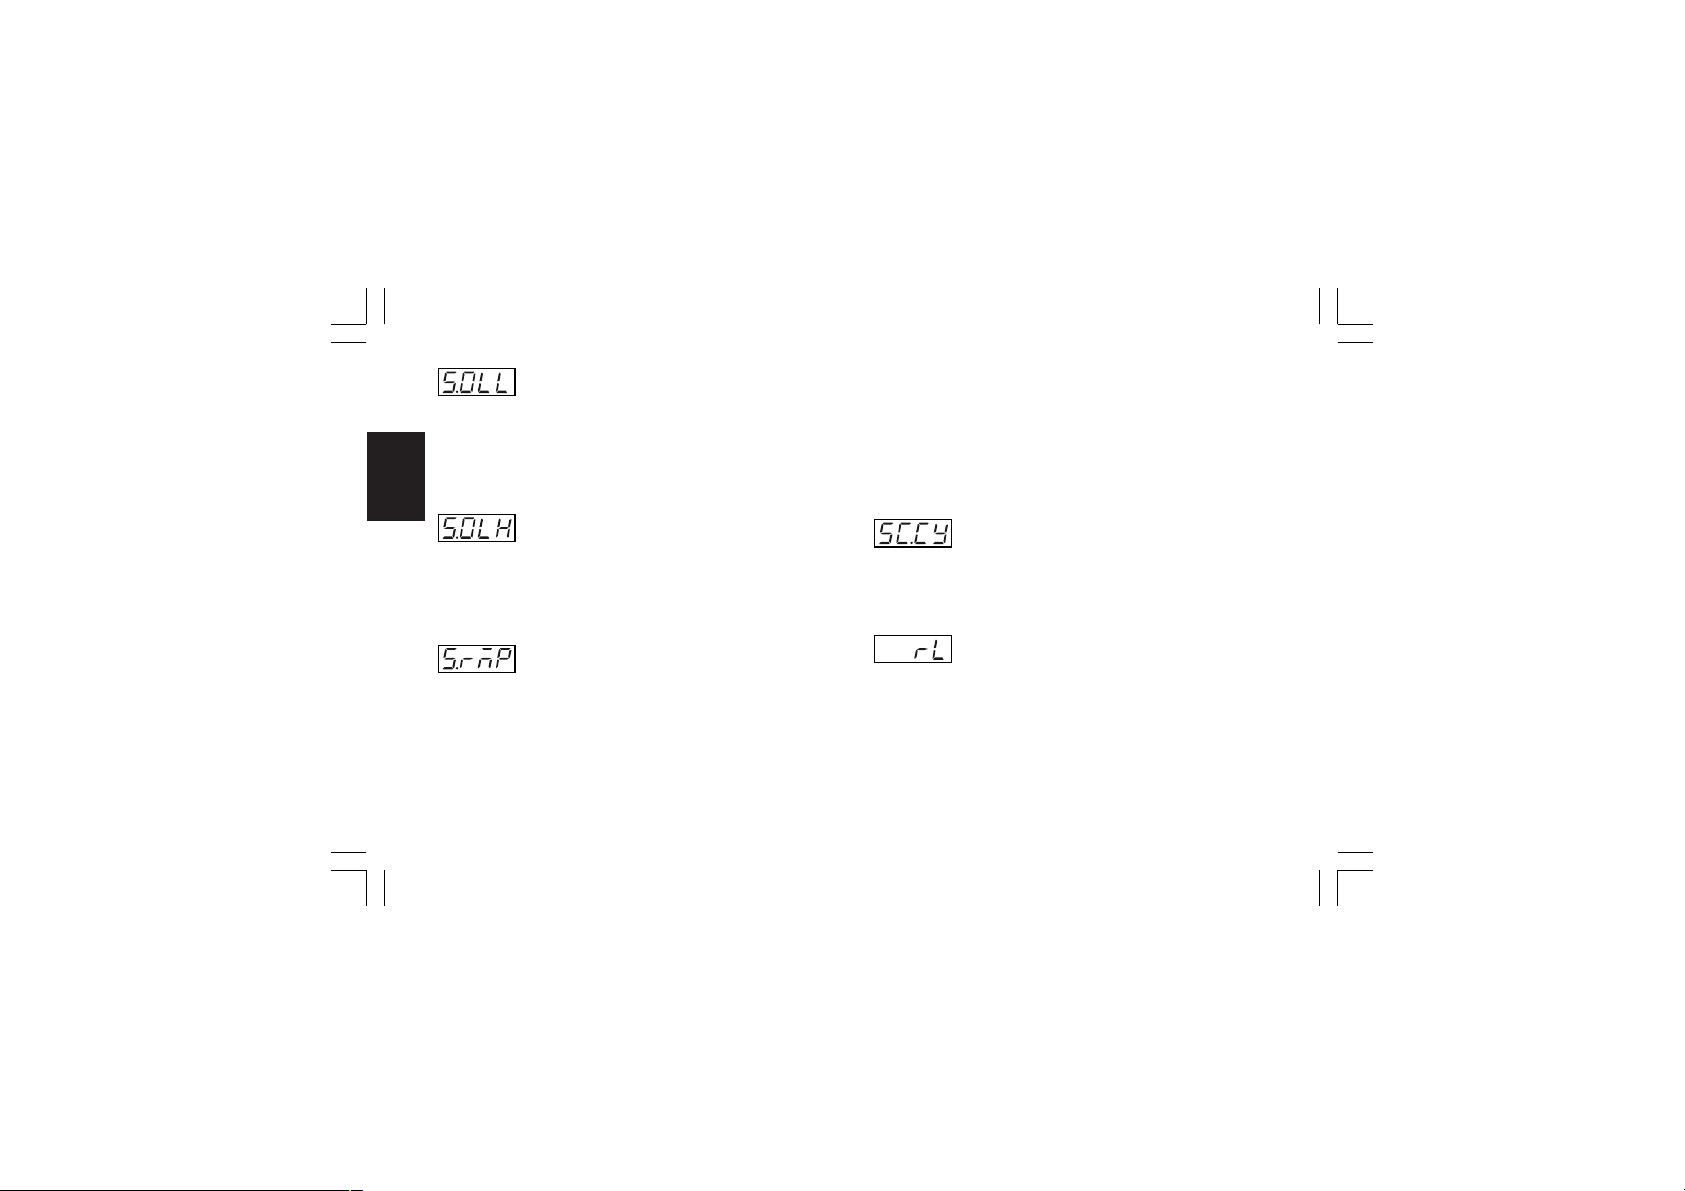
- Secondary control output low limit - [r.E08]
This parameter is available when one control output is
configured as secondary control output.
Range: From 0.0 % of the output span to S.OLH [r.E09].
Gr.5
- Secondary control output high limit - [r.E09]
This parameter is available when one control output is
configured as secondary control output.
Range: from S.OLL [r.E08] to 100.0 % of the output span
NOTES:
1) This parameter will be active even if device is configured for
On/OFF control.
2) During the transfer from AUTO to MANUAL, if this action is
programmed as a not bumpless transfer, the “S.rñP” function
will be ignored and the output will step up to the value set by
“Añ.UL” [C.G04] parameter.
- Secondary output cycle time - [r.E11]
This parameter is available when a time proportional secondary
control output is configured.
Range: from 1 to 200 s
- Secondary control output max rate of rise
- [r.E10]
This parameter is available when one control output is
configured as secondary control output.
Ranges: from 0.1%/s to 25.0%/s.
Above this value the display shows “Inf” meaning that no limit is
imposed
Xkc-1-C0.P65 5/29/02, 11:59 AM86
- Set point low limit - [r.E12]
Range: From “ñ.In.L” [C.d05] to rH [r.E13].
NOTES: Whenever “ñ.In.L” [C.d05] has been modified, the
following occurs:
1) rL will be realigned to it;
2) if the set point values are out of the new limits, the set point
automatically assumes the default value.
86
Page 91
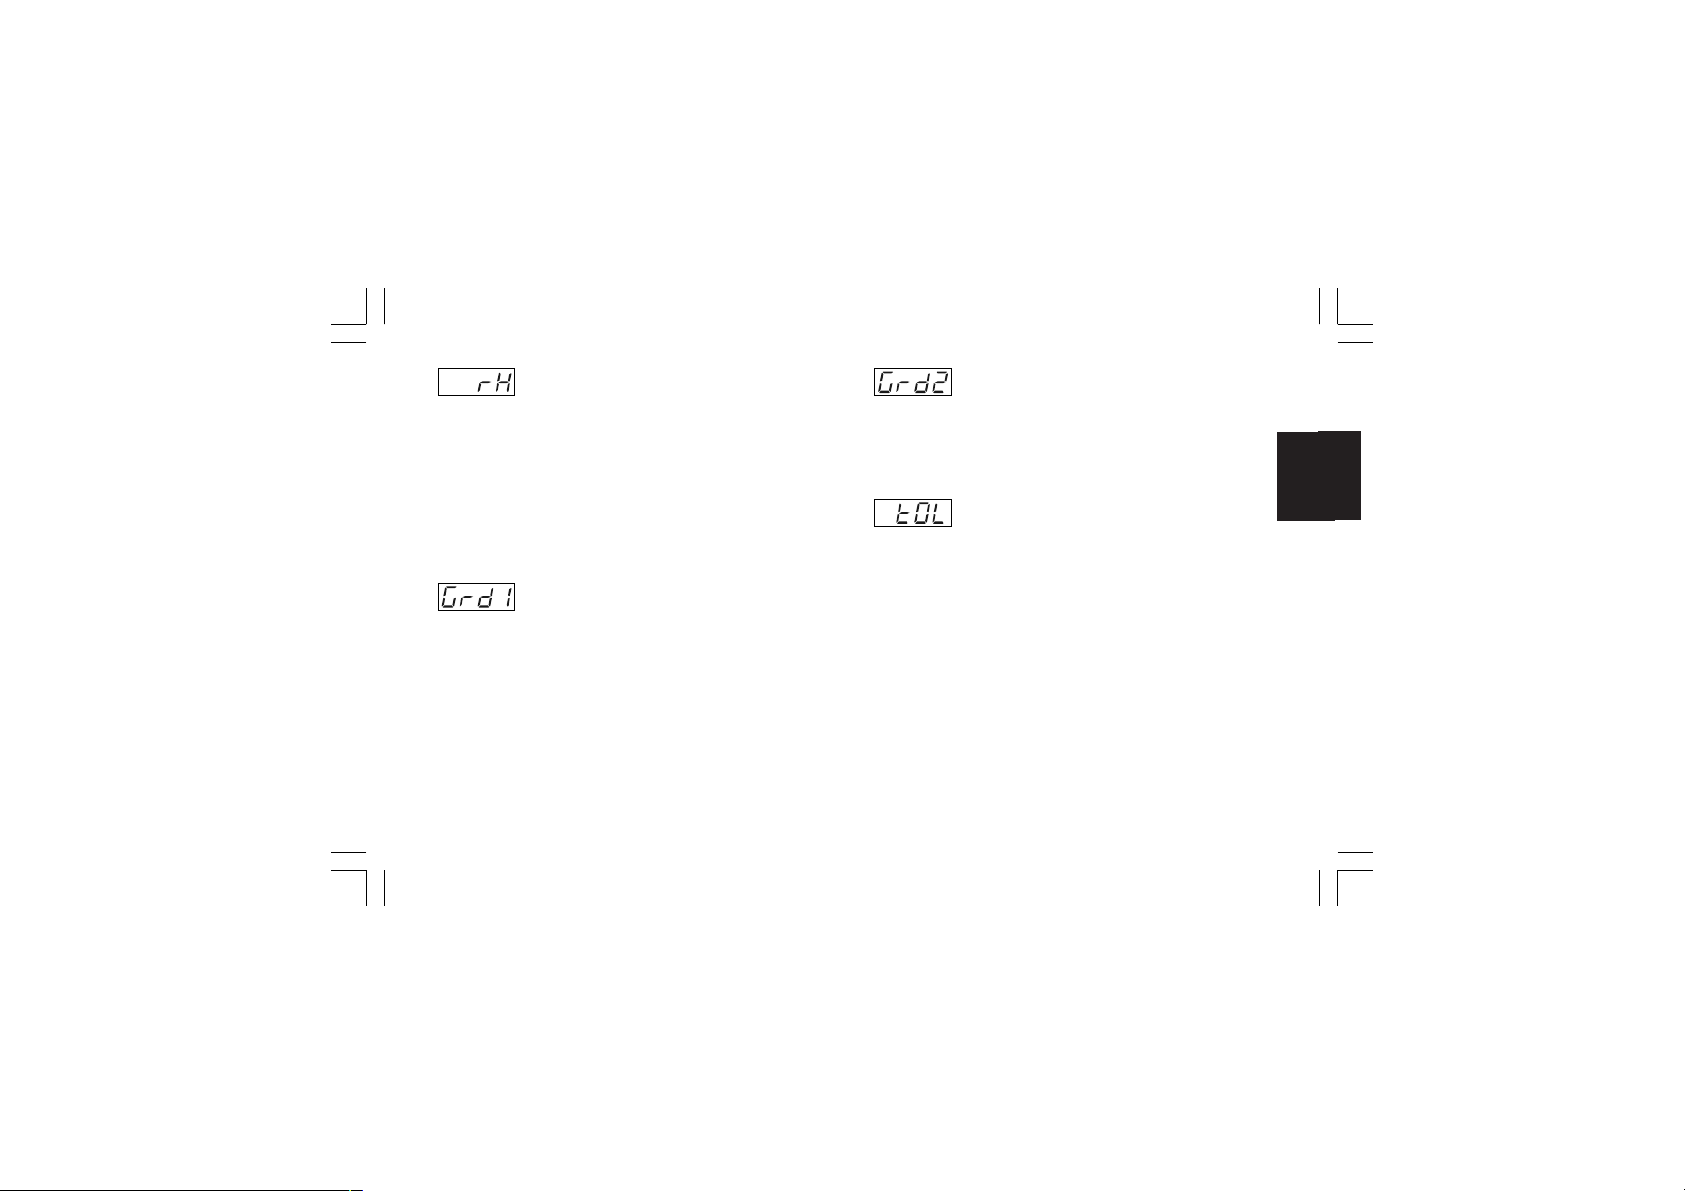
- Set point high limit - [r.E13]
Range: from rL [r.E12] to “ñ.In.H” [C.d06].
NOTES: Whenever “ñ.In.H” [C.d06] has been modified, the
following occurs:
1) rH will be realigned to it;
2) if the set point values are out of the new limits, "rH"
automatically assumes the default value.
- Rate of change for positive set point
variations - [r.E14]
Range: from 1 to 200 digits per minute.
Above this value the display shows “Inf” and the transfer will be
a step change.
Xkc-1-C0.P65 5/29/02, 11:59 AM87
- Rate of change for negative set point
variations - [r.E15]
Range: from 1 to 200 digits per minutes.
Above this value the display shows “Inf” and the transfer will be
a step change.
- Time out for the soft start - [r.E16]
This parameter is available when at least one output is
configured as control output and no logic input is configured as
“Output limiter activator”.
Range: from 1 to 540 min.
Above this value the display shows “InF” and the limiting action
is always active.
NOTE: The tOL can be always modified but the new value will be
used only at the next device power up
87
Gr.5
Page 92
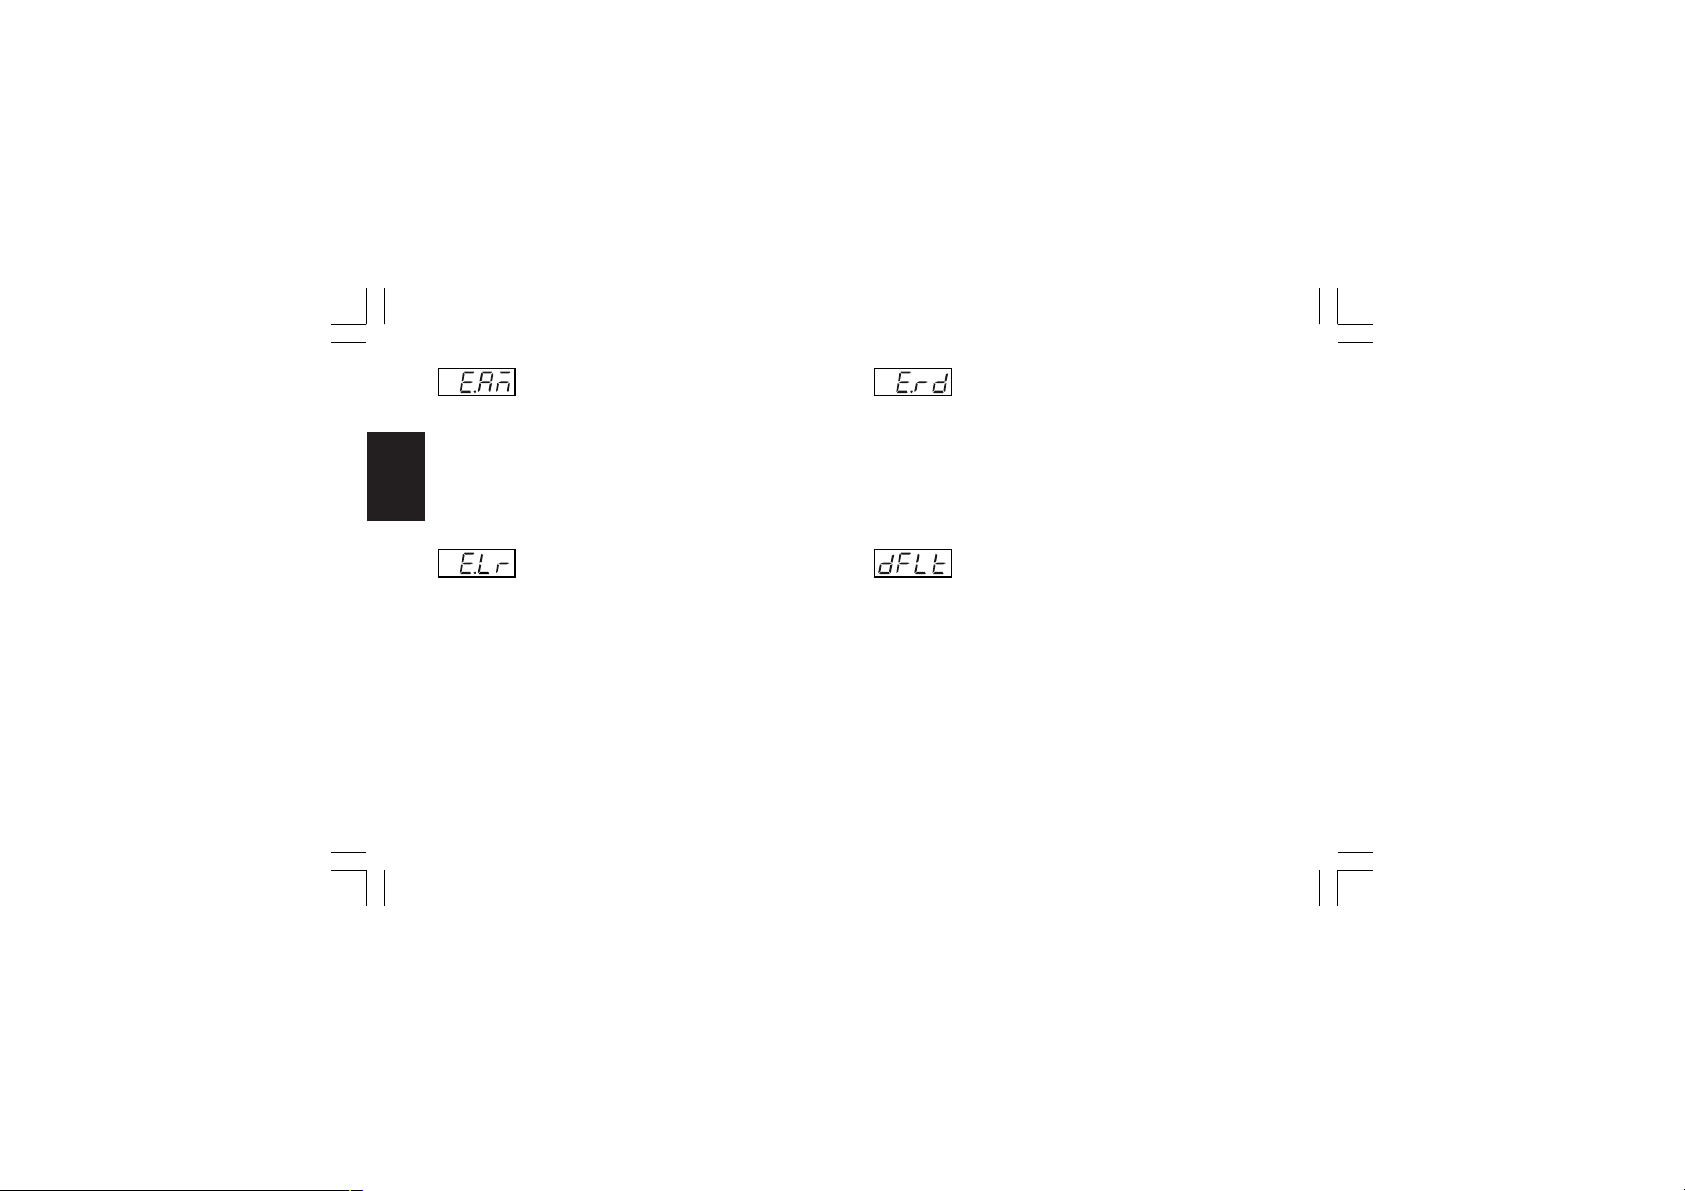
- External control for AUTO /MANUAL mode
- [r.E17]
This parameter is available when one of the logic inputs is
configured for Auto/Manual selection.
Range: On the Auto/Manual selection is made by logic input
only
OFF the Auto/Manual selection is made by “Man” key
or serial link only
Gr.5
- External control for reverse/direct output
action selection - [r.E19]
This parameter is available when one of the logic inputs is
configured for direct/reverse output action selection.
Range: On the reverse/direct selection is made by external
contact only
OFF the reverse/direct selection is made by “Cn.Ac”
[r.d08] parameter or serial link only.
- External control for local/remote set point
selection - [r.E18]
This parameter is available when one of the logic inputs is
configured for Local/Remote set point selection and “A.I.Añ”
[C.d14] is equal to “norñ”.
Range: On the local/remote set point selection is made by
external contact only
OFF the local/remote selection is made by “RSP”
push-button or serial link only.
Xkc-1-C0.P65 5/29/02, 11:59 AM88
- Group 5 default data loading - [r.E20]
Range: OFF = No loading data
ON = Loading data
88
Page 93
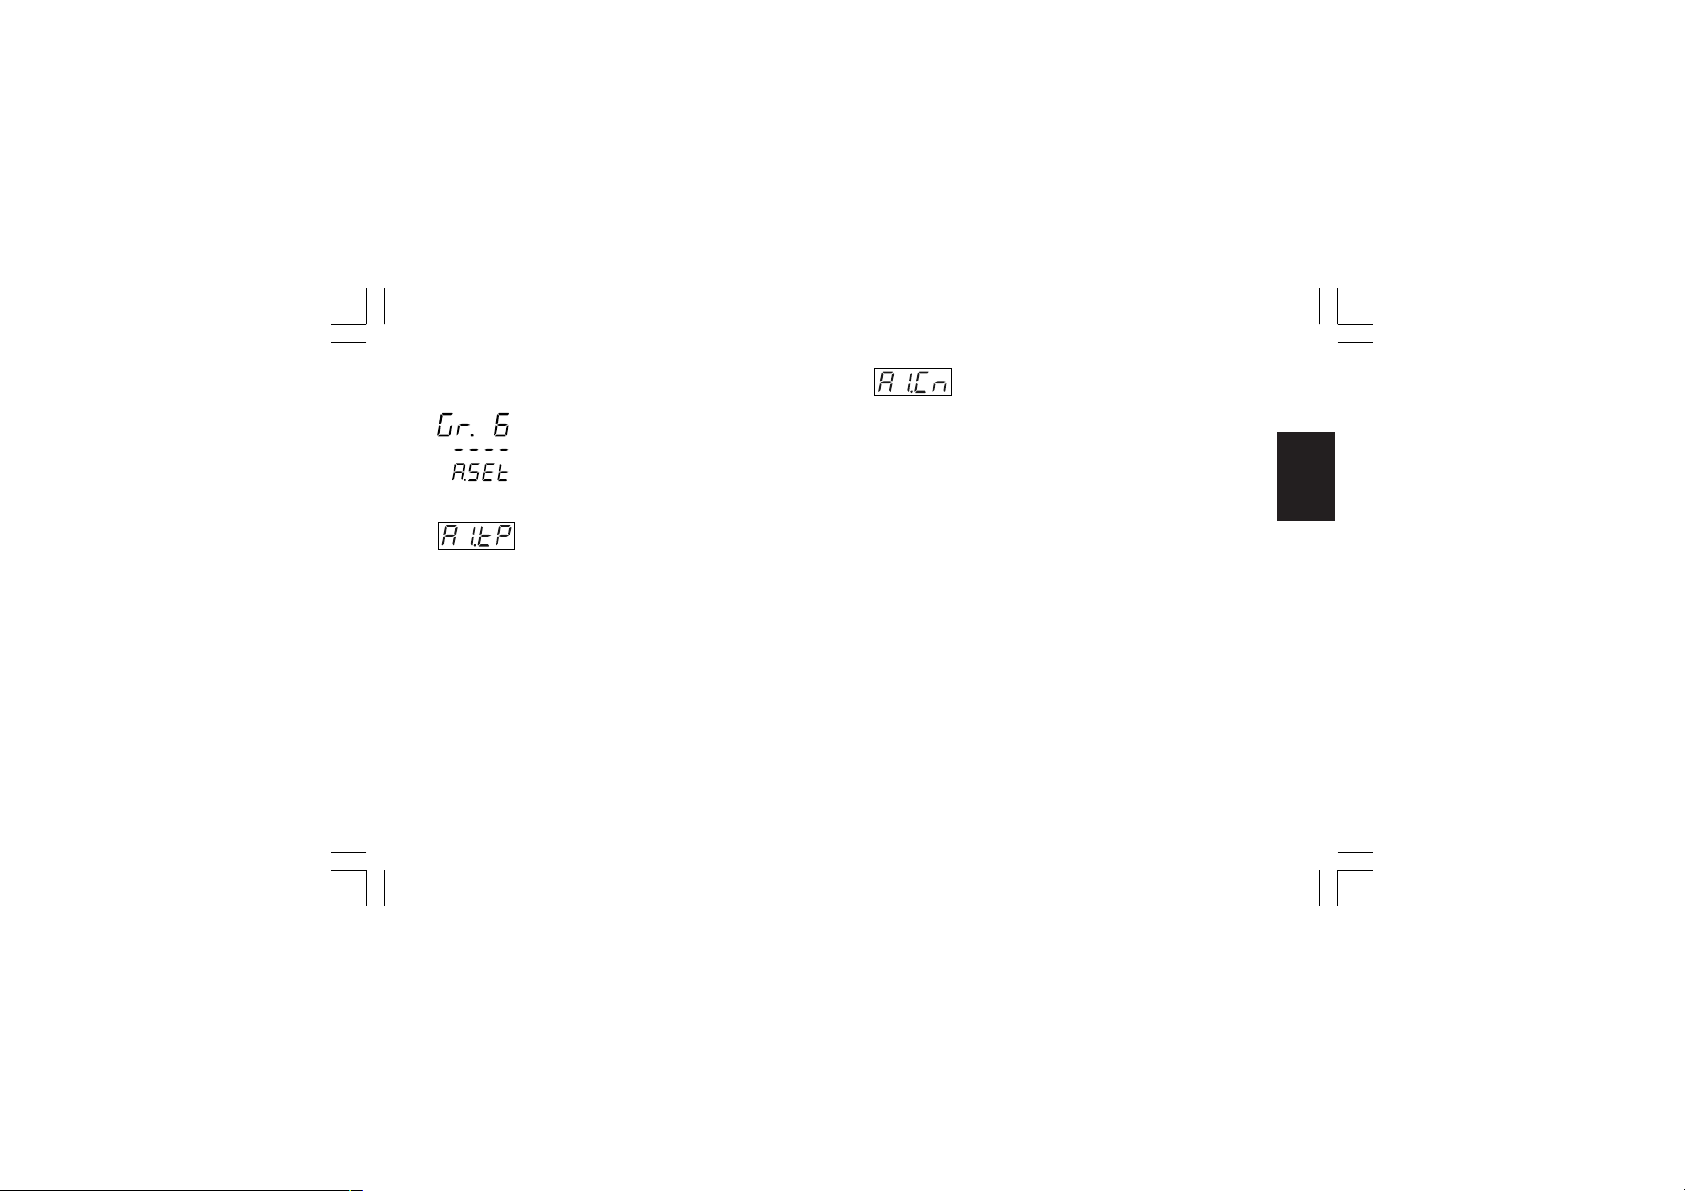
Run time group 6 [r.Fxx]
ALARM SETTING
- Alarm 1 type - [r.F01]
This parameter is available only when OUT 1 is configured as
alarm 1 output (“O1.Fn” [C.E01] = “ALr.1”)
Range: Proc = Alarm on process variable
bAnd = Band alarm on process variable
dEV = Deviation alarm on process variable
ñAin = Alarm on Main control output value
SECn = Alarm on Secondary control output value
NOTE: When alarm type has been changed the alarm threshold
will be forced to its default value and alarm status will be
cleared.
Xkc-1-C0.P65 5/29/02, 11:59 AM89
- Alarm 1 configuration - [r.F02]
This parameter is available only when OUT 1 is configured as
alarm 1 output (“O1.Fn” [C.E01] = “ALr.1”)
Range: H.A. = High alarm (outside band) with automatic reset
L.A. = Low alarm (inside band) with automatic reset
H.A.Ac= High alarm (outside band) with automatic reset
and acknowledge
L.A.Ac= Low alarm (inside band) with automatic reset
and acknowledge
H.L. = High alarm (outside band) with manual reset
L.L. = Low alarm (inside band) with manual reset
NOTE: When alarm configuration has been changed, the alarm
status will be cleared.
89
Gr.6
Page 94
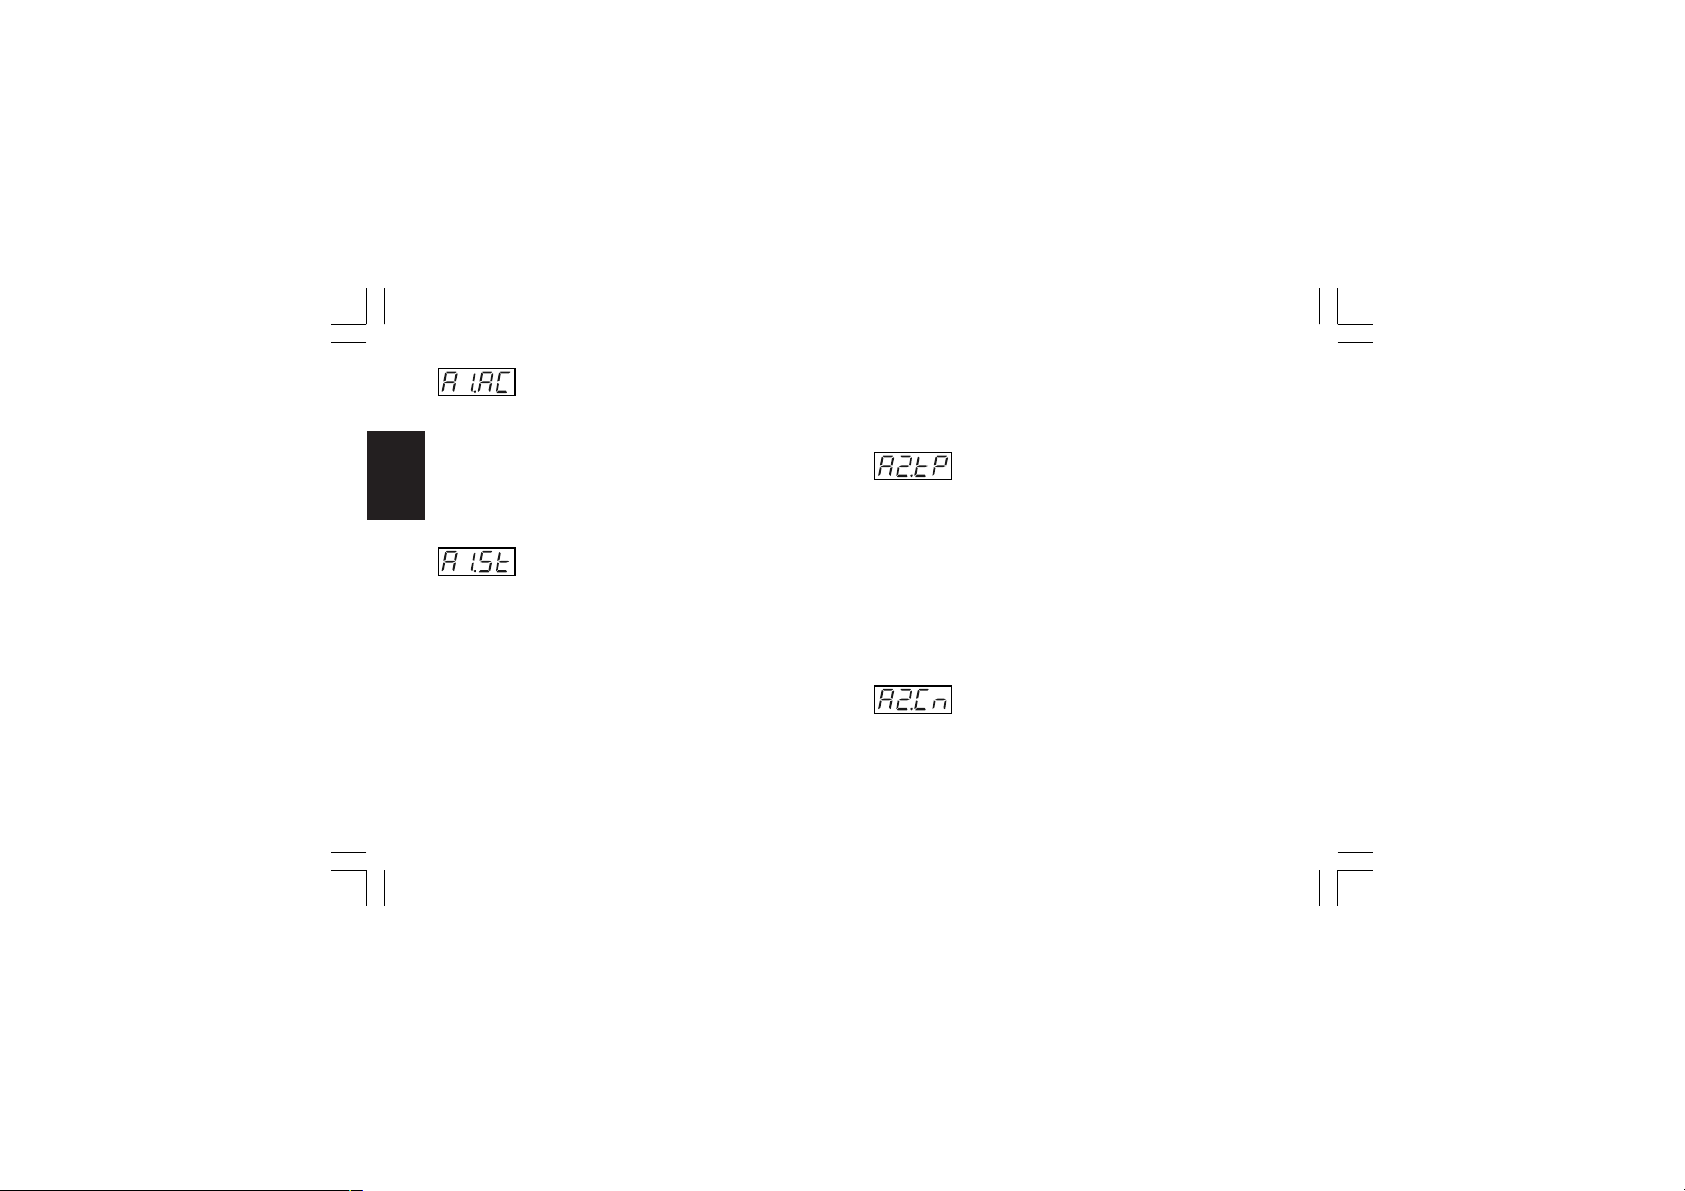
- Alarm 1 action - [r.F03]
This parameter is available only when OUT 1 is configured as
alarm 1 output (“O1.Fn” [C.E01] = “ALr.1”)
Range: dir = direct action (Relay energized or SSr=1 in
alarm condition)
rEV = Reverse action (Relay energized or SSr=1 in
Gr.6
non alarm condition)
- Alarm 1 stand by (mask) function - [r.F04]
This parameter is available only when OUT 1 is configured as
alarm 1 output (“O1.Fn” [C.E01] = “ALr.1”)
Range: OFF = Stand-by function disabled
On = Stand-by function enabled
NOTES:
1) If the alarm is programmed as band or deviation alarm, this
function masks the alarm condition after a set point change or
at the instrument start-up until process variable reaches the
alarm threshold plus or minus hysteresis. If the alarm is
programmed as a process alarm or control output alarm, this
function masks the alarm condition at instrument start-up until
process variable reaches the alarm threshold plus or minus
hysteresis.
Xkc-1-C0.P65 5/29/02, 11:59 AM90
2) The change from On to OFF has immediate effect, while the
change from OFF to On has effect at the next start up or set
point change.
- Alarm 2 type - [r.F05]
This parameter is available only when OUT 2 is configured as
alarm 2 output (“O2.Fn” [C.E02] = “ALr.2”)
Range: Proc = Alarm on process variable
bAnd = Band alarm on process variable
dEV = Deviation alarm on process variable
ñAin = Alarm on Main control output value
SECn = Alarm on Secondary control output value
NOTE: When alarm type has been changed the alarm threshold
will be forced to its default value and alarm status will be
cleared.
- Alarm 2 configuration - [r.F06]
This parameter is available only when OUT 2 is configured as
alarm 2 output (“O2.Fn” [C.E02] = “ALr.2”)
Range: H.A. = High alarm (outside band) with automatic reset
L.A. = Low alarm (inside band) with automatic reset
90
Page 95
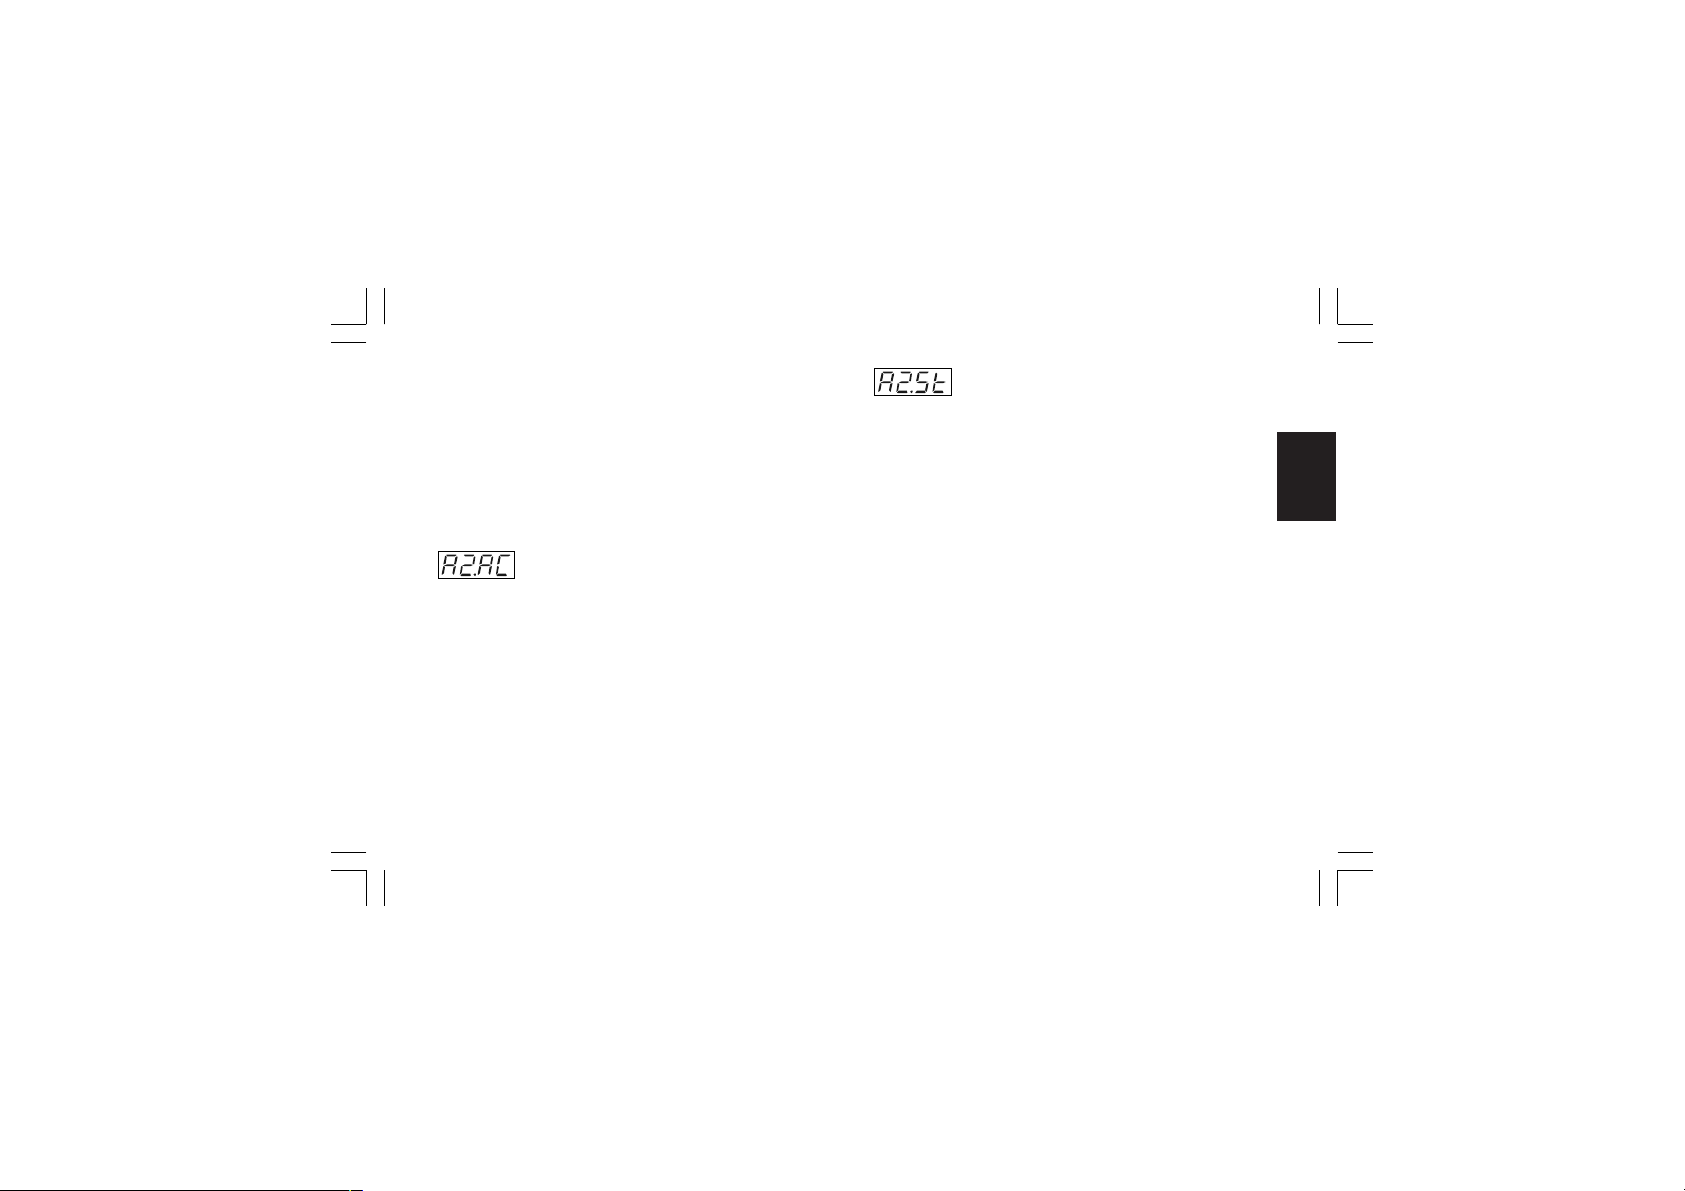
H.A.Ac= High alarm (outside band) with automatic reset
and acknowledge
L.A.Ac= Low alarm (inside band) with automatic reset
and acknowledge
H.L. = High alarm (outside band) with manual reset
L.L. = Low alarm (inside band) with manual reset
NOTE: When alarm configuration has been changed, the alarm
status will be cleared.
- Alarm 2 action - [r.F07]
This parameter is available only when OUT 2 is configured as
alarm 2 output (“O2.Fn” [C.E02] = “ALr.2”)
Range: dir = direct action (Relay energized or SSr=1 in
alarm condition)
rEV = Reverse action (Relay energized or SSr=1 in
non alarm condition)
Xkc-1-C0.P65 5/29/02, 11:59 AM91
- Alarm 2 stand by (mask) function - [r.F08]
This parameter is available only when OUT 2 is configured as
alarm 2 output (“O2.Fn” [C.E02] = “ALr.2”)
Range: OFF = Stand-by function disabled
On = Stand-by function enabled
NOTES:
1) If the alarm is programmed as band or deviation alarm, this
function masks the alarm condition after a set point change or
at the instrument start-up until process variable reaches the
alarm threshold plus or minus hysteresis. If the alarm is
programmed as a process alarm or control output alarm, this
function masks the alarm condition at instrument start-up until
process variable reaches the alarm threshold plus or minus
hysteresis.
2) The change from On to OFF has immediate effect, while the
change from OFF to On has effect at the next start up or set
point change
91
Gr.6
Page 96
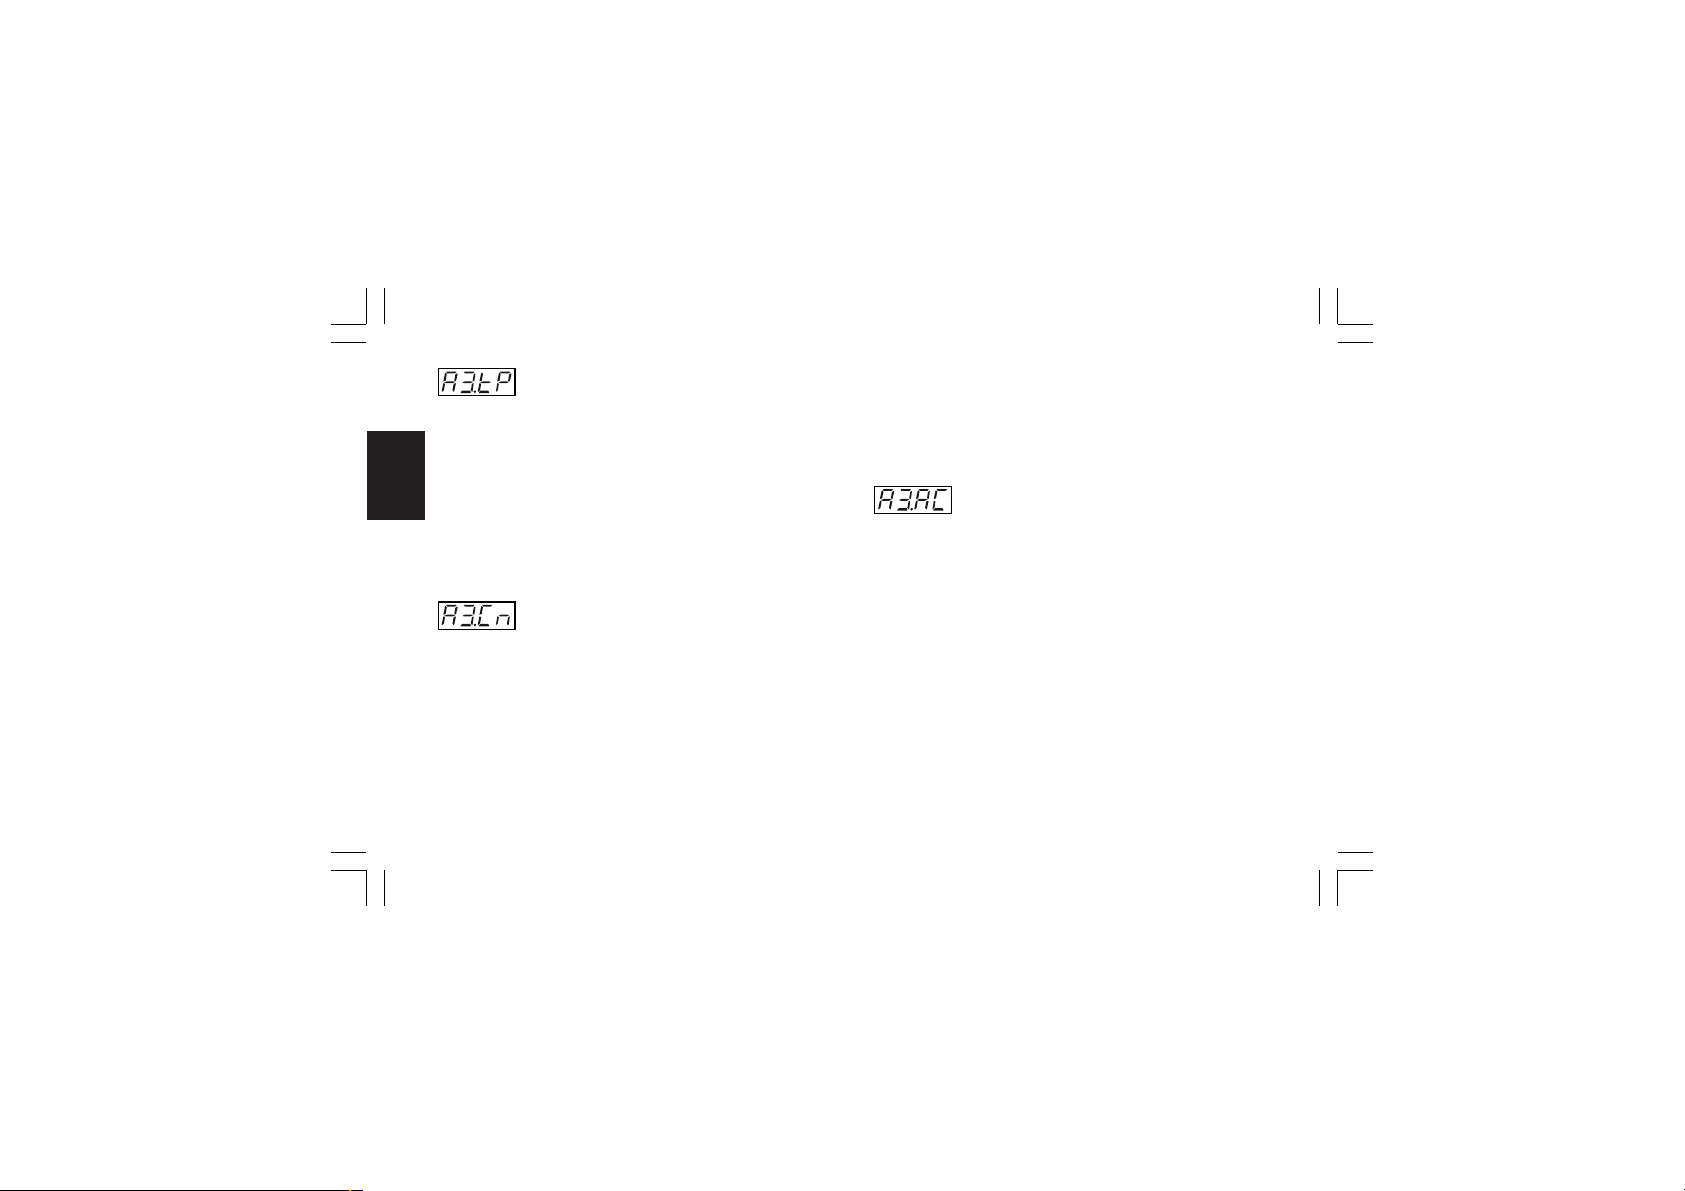
- Alarm 3 type - [r.F09]
This parameter is available only when OUT 3 is configured as
alarm 3 output (“O3.Fn” [C.E03] = “ALr.3”)
Range: Proc = Alarm on process variable
bAnd = Band alarm on process variable
dEV = Deviation alarm on process variable
Gr.6
ñAin = Alarm on Main control output value
SECn = Alarm on Secondary control output value
NOTE: When alarm type has been changed the alarm threshold
will be forced to its default value and alarm status will be
cleared.
- Alarm 3 configuration - [r.F10]
This parameter is available only when OUT 3 is configured as
alarm 3 output (“O3.Fn” [C.E03] = “ALr.3”)
Range: H.A. = High alarm (outside band) with automatic reset
L.A. = Low alarm (inside band) with automatic reset
H.A.Ac= High alarm (outside band) with automatic reset
and acknowledge
L.A.Ac= Low alarm (inside band) with automatic reset
and acknowledge
Xkc-1-C0.P65 5/29/02, 11:59 AM92
H.L. = High alarm (outside band) with manual reset
L.L. = Low alarm (inside band) with manual reset
NOTE: When alarm configuration has been changed, the alarm
status will be cleared.
- Alarm 3 action - [r.F11]
This parameter is available only when OUT 3 is configured as
alarm 3 output (“O3.Fn” [C.E03] = “ALr.3”)
Range: dir = direct action (Relay energized or SSr=1 in
alarm condition)
rEV = Reverse action (Relay energized or SSr=1 in
non alarm condition)
92
Page 97
- Alarm 3 standby (mask) function - [r.F12]
This parameter is available only when OUT 3 is configured as
alarm 3 output (“O3.Fn” [C.E03] = “ALr.3”)
Range: OFF = Stand-by function disabled
On = Stand-by function enabled
NOTES:
1) If the alarm is programmed as band or deviation alarm, this
function masks the alarm condition after a set point change or
at the instrument start-up until process variable reaches the
alarm threshold plus or minus hysteresis. If the alarm is
programmed as a process alarm or control output alarm, this
function masks the alarm condition at instrument start-up until
process variable reaches the alarm threshold plus or minus
hysteresis.
2) The change from On to OFF has immediate effect, while the
change from OFF to On has effect at the next start up or set
point change
Xkc-1-C0.P65 5/29/02, 11:59 AM93
- Alarm 4 type - [r.F13]
This parameter is available only when OUT 4 is configured as
alarm 4 output (“O4.Fn” [C.E04] = “ALr.4”)
Range: Proc = Alarm on process variable
bAnd = Band alarm on process variable
dEV = Deviation alarm on process variable
ñAin = Alarm on Main control output value
SECn = Alarm on Secondary control output value
NOTE: When alarm type has been changed the alarm threshold
will be forced to its default value and alarm status will be
cleared.
- Alarm 4 configuration - [r.F14]
This parameter is available only when OUT 4 is configured as
alarm 4 output (“O4.Fn” [C.E04] = “ALr.4”)
Range: H.A. = High alarm (outside band) with automatic reset
L.A. = Low alarm (inside band) with automatic reset
H.A.Ac= High alarm (outside band) with automatic reset
and acknowledge
L.A.Ac= Low alarm (inside band) with automatic reset
and acknowledge
93
Gr.6
Page 98
H.L. = High alarm (outside band) with manual reset
L.L. = Low alarm (inside band) with manual reset
NOTE: When alarm configuration has been changed, the alarm
status will be cleared.
Gr.6
- Alarm 4 action - [r.F15]
This parameter is available only when OUT 4 is configured as
alarm 4 output (“O4.Fn” [C.E04] = “ALr.4”)
Range: dir = direct action (Relay energized or SSr=1 in
alarm condition)
rEV = Reverse action (Relay energized or SSr=1 in
non alarm condition)
Xkc-1-C0.P65 5/29/02, 11:59 AM94
- Alarm 4 stand-by (mask) function - [r.F16]
This parameter is available only when OUT 4 is configured as
alarm 4 output (“O4.Fn” [C.E04] = “ALr.4”)
Range: OFF = Stand-by function disabled
On = Stand-by function enabled
NOTES:
1) If the alarm is programmed as band or deviation alarm, this
function masks the alarm condition after a set point change or
at the instrument start-up until process variable reaches the
alarm threshold plus or minus hysteresis. If the alarm is
programmed as a process alarm or control output alarm, this
function masks the alarm condition at instrument start-up until
process variable reaches the alarm threshold plus or minus
hysteresis.
2) The change from On to OFF has immediate effect, while the
change from OFF to On has effect at the next start up or set
point change
94
Page 99
- OFD (Output Failure Detection) alarm
configuration - [r.F17]
This parameter is available only when OFD option is configured
(“Fd.Fn” [C.I11] equal to “ñC.On” or “ñC.OF” or “SC.On” or
“SC.OF”).
Range: A. = Alarm with automatic reset
A.Ac = Alarm with automatic reset and acknowledge
L. = Alarm with manual reset
NOTE: When alarm configuration has been changed, the alarm
status will be cleared.
- OFD (Output Failure Detection) alarm action
- [r.F18]
This parameter is available only when one output is configured
as OFD alarm annunciator (“Fd.Fn” [C.I11] equal to “ñC.On” or
“ñC.OF” or “SC.On” or “SC.OF” and “Fd.Ou” [C.I13] is different
from “nonE”).
Range: dir = direct action (Relay energized or SSr=1 in
alarm condition)
rEV = Reverse action (Relay energized or SSr=1 in
non alarm condition)
Xkc-1-C0.P65 5/29/02, 11:59 AM95
NOTE: When OFD output is in OR condition with an alarm or an
event output, the “Fd.Ac” parameter can only be monitored but
not modified and it assumes the same action defined (by “Alarm
Action” or “Event Logic Level”) for the alarm or the event.
- Group 6 default data loading - [r.F19]
Range: OFF = No loading data
ON = Loading data
95
Gr.6
Page 100
Run time group 7 [r.Gxx]
SERIAL LINK PARAMETER
- Serial link baud rate - [r.G03]
This parameter is available only when “S.L.Pr” [r.G01] is
different from "OFF".
Range: from 600 to 19200 baud (19200 baud is shown, on
display, as 19.20)
Gr.7
- Serial interface protocol - [r.G01]
Range: OFF = No serial interface
ñbUS = Modbus
jbUS = Jbus
NOTE: When serial interface circuit is not mounted, the middle
display will show “no.Pr”
- Serial link device address - [r.G02]
This parameter is available only when “S.L.Pr” [r.G01] is
different from "OFF".
Range: from 1 to 255
Xkc-1-C0.P65 5/29/02, 11:59 AM96
- Serial link byte format - [r.G04]
This parameter is available only when “S.L.Pr” [r.G01] is
different from "OFF".
Range: 8 = 8 bits without parity
8E = 8 bits + even parity
8O = 8 bits + odd parity
- Group 7 default data loading - [r.G05]
Range: OFF = No loading data
ON = Loading data
96
 Loading...