

Page 1
INTEGRATED CIRCUITS
XA-H3
CMOS 16-bit highly integrated
microcontroller
Preliminary specification
IC28 Data Handbook
1999 Sep 24
Page 2
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
DESCRIPTION
The powerful 16-bit XA CPU core and rich feature set make the
XA-H3 and XA-H4 devices ideal for high-performance real-time
applications such as industrial control and networking. By supporting
of up to 32 MB of external memory, these devices provide a low-cost
solution to embedded applications of any complexity. Features like
DMA, memory controller and four advanced UARTs help solve I/O
intensive tasks with a minimum of CPU load.
FEA TURES
•Large Memory Support (up to 6 MB external)
•De-multiplexed Address/Data Bus
•Six Programmable Chip Selects
– Support for Unified Memory – allows easy user modification of
all code
– External ISP Flash support for easy code download
•Dynamic Bus Sizing – each of 6 Chip Selects can be programmed
for 8-bit or 16-bit bus.
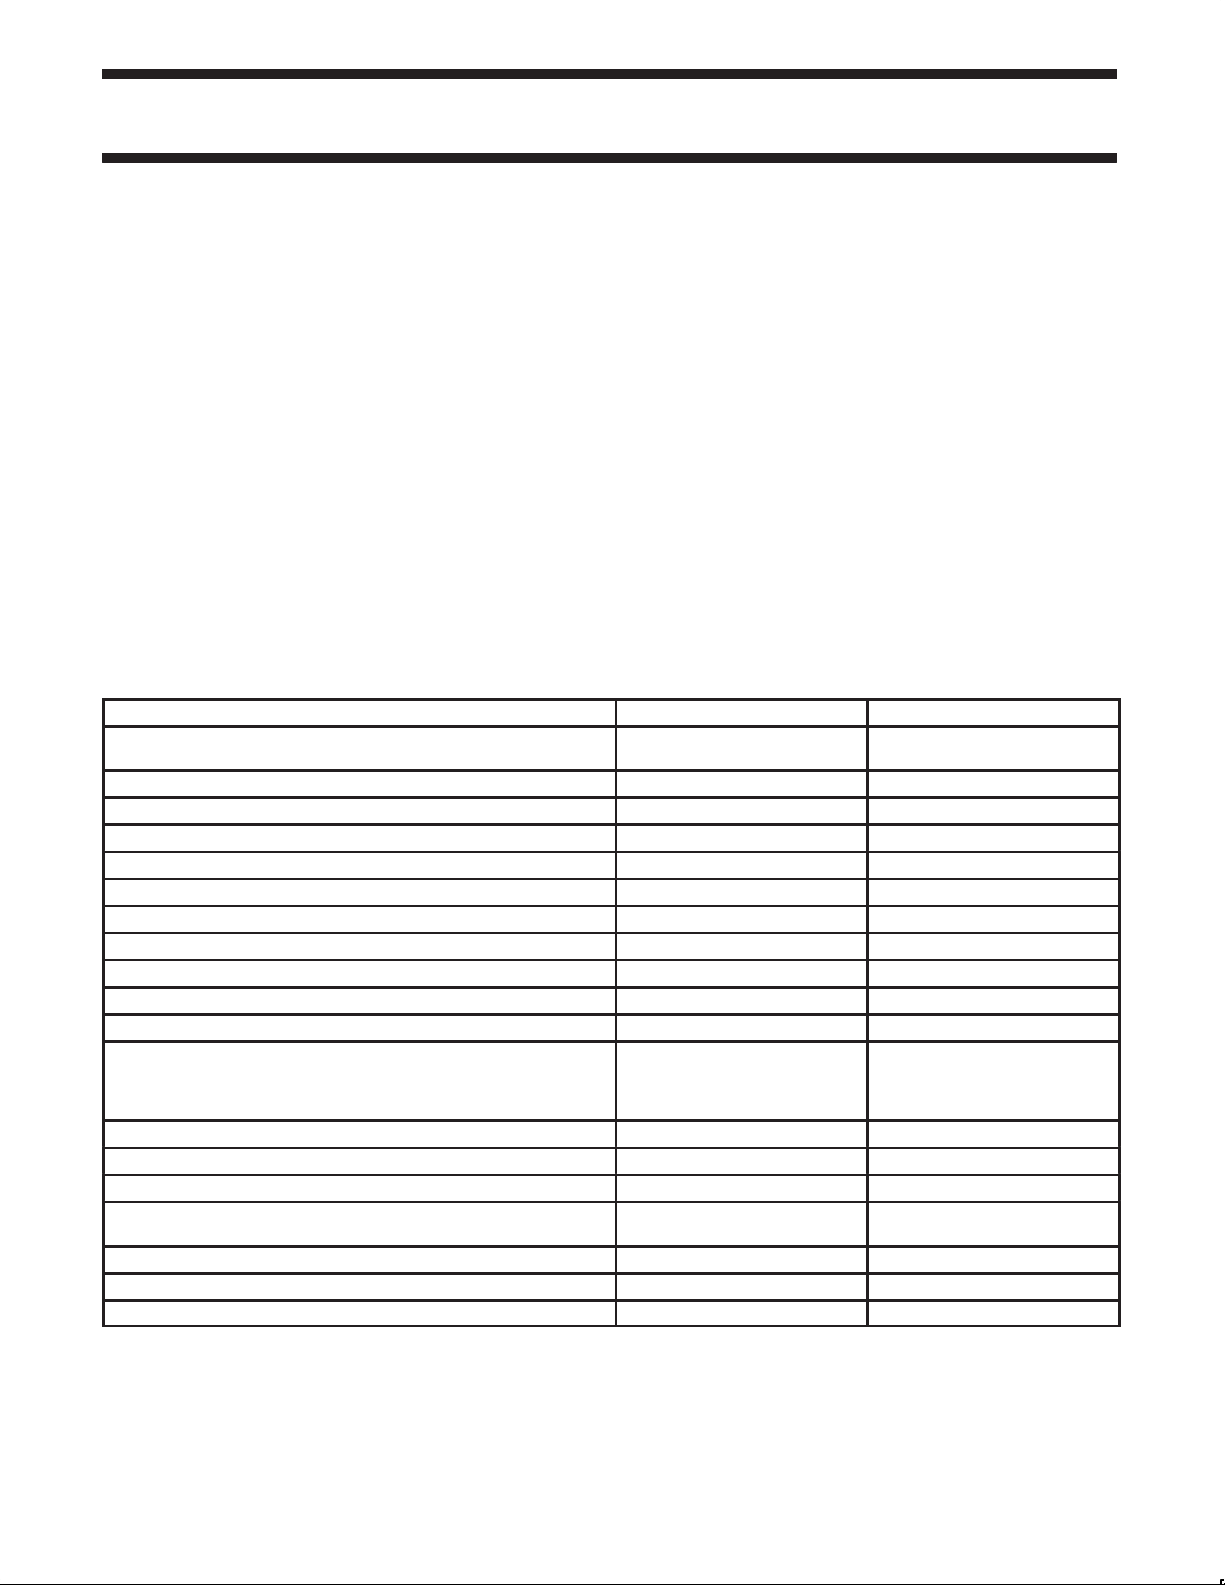
The XA-H3 feature set is a subset of the XA-H4 (see Table 1). The
XA-H3/H4 devices are members of the Philips XA (eXtended
Architecture) family of high performance 16-bit microcontrollers.
The XA-H3 and XA-H4 are designed to significantly minimize the
need for external components.
•Dynamic Bus Timing – each of 6 chip selects has individual
programmable bus timing.
•32 Programmable General Purpose I/O Pins
•Four UARTs with 230.4 kbps capability
•Eight DMA Channels
Table 1. XA-H3 and XA-H4 features comparison
Feature XA-H3 XA-H4
Maximum External Memory
(Harvard Memory Mode)
Maximum External Memory (Unified Memory Mode) 6 MB 16 MB
Memory Controller supports both Harvard and Unified architectures Yes Yes
De-multiplexed Address/Data Bus Yes Yes
DRAM Controller No Yes
DMA Channels 8 8
Dynamic Bus Sizing Yes Yes
Dynamic Bus Timing Yes Yes
Programmable Chip Selects 6 6
General Purpose IO Pins 33 33
Potential Interrupt Pins 16 16
Interrupts (programmable priority) 7 Standard SW
Counter/Timers 2 plus Watchdog 2 plus Watchdog
Baud Rate Generators
Serial Ports 4 UARTS 4 USARTS
Maximum Serial Data Rates asynch to 230.4 kbps (no sync) asynch to 230.4 kbps
Match Characters No 4 async chars per USART
Hardware Autobaud No up to 230.4 kbps
SCP/SPI Bus No
NOTE:
1. Can be used as additional counters if not needed as BRGs.
1
6 MB 32 MB
(16 MB Code, 16 MB Data)
4 High Priority SW
13 Hardware Event
4 4
7 Standard SW
4 High Priority SW
13 Hardware Event
sync to 1 Mbps
1999 Sep 24
2
Page 3
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
ORDERING INFORMATION
ROMless Only Temperature range °C and Package Freq (MHz) Package Drawing Number
H3 = PXAH30KFBE
–40 to +85°C, 100-Pin Low Profile Quad Flat Package (LQFP)
NOTE
K=30 MHz, F = (–40 to +85), BE = LQFP
PIN CONFIGURATION
RxD0
GPOut
P0.6
P0.7
9998979695949392919089888786858483828180797877
100
1VSS
2
VDD
A0
3
A1
4
A2
5
A3
6
A4
7
A5
8
A6
9
A7
10
A8
11
A9
12
A10
13
A11
14
A12
15
A13
16
A14
17
A15
18
VSS
19
VDD
20
A16
21
A17
22
A18
23
A19
24
D0
25
26272829303132333435363738394041424344454647484950
D2
D1
VSS
VDD
P2.6_RTS3
P2.7_BRG3
VSS
VDD
P0.0_BRG0
P0.1_RTS0
P0.2_CTS0
P0.3_CD0
P0.4_TRClk0
P0.5_RTClk0
TxD0
XA-H3
Top View 100 Pin LQFP
Part Number: PXAH30KFBE
K = 30 MHz, F = –40 to +85°C, BE = LQFP pkg
LQFP Package = SOT407-1
MOLD MARK
D9
D8
D7
D6
D5
D4
D3
D10
D11
D13
D12
P2.3_ComClk_TRClk3
P2.4_CD3
P2.5_CTS3
D15
D14
VDD
30 SOT407-1
CD1_Int2
VSS
VDD
Int0
P2.0_RxD3
P2.1_TxD3
P2.2_RTClk3
76
MOLD MARK
WE
CS0
CS1
CS2
CS3
VSS
ClkOut
75
P1.7_BRG2
74
P1.6_RTS2
P1.5_CTS2
73
P1.4_CD2
72
P1.3_TRClk2
71
P1.2_RTClk2
70
P1.1_TxD2
69
P1.0_RxD2
68
P3.7_Int1_TRClk1
67
P3.6_TxD1
66
P3.5_RxD1
65
P3.4_CTS1
64
P3.3_Timer1_BRG1
63
VDD
62
XTALOUT
61
XTALIN
60
VSS
59
P3.2_Timer0_ResetOut
58
P3.1_CS5_RTS1
57
P3.0_CS4_RTClk1
56
Reset_In
55
BLE
54
BHE
53
WAIT_Size16
52
OE
51
1999 Sep 24
SU01234
3
Page 4

Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
LOGIC SYMBOL XA-H3
V
DDVSS
MISC. UART1 PORT3
Int2
CS4
CS5
ResetOut, Timer0
Timer1
Int1
Int0
CD1
RTClk1
RTS1
BRG1
CTS1
RxD1
TxD1
TRClk1
UART3
RxD3
TxD3
RTClk3
ComClk, TRClk3
CD3
CTS3
RTS3
BRG3
3.0
3.1
3.2
3.3
3.4
3.5
3.6
3.7
PORT2
2.0
2.1
2.2
2.3
2.4
2.5
2.6
2.7
XTAL1
XTAL2
CS3
CS2
CS1
CS0
A19 – A0
D15 – D0
UART2
RxD2
TxD2
RTClk2
TRClk2
CD2
CTS2
RTS2
BRG2
TxD0
RxD0
BRG0
RTS0
CTS0
CD0
TRClk0
RTClk0
GPOut
PORT1
1.0
1.1
1.2
1.3
1.4
1.5
1.6
1.7
PORT0UART0
0.0
0.1
0.2
0.3
0.4
0.5
0.6
0.7
ClkOut
BHE
BLE
OE
WE
Wait, Size16
ResetIn
SU01235
1999 Sep 24
4
Page 5
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
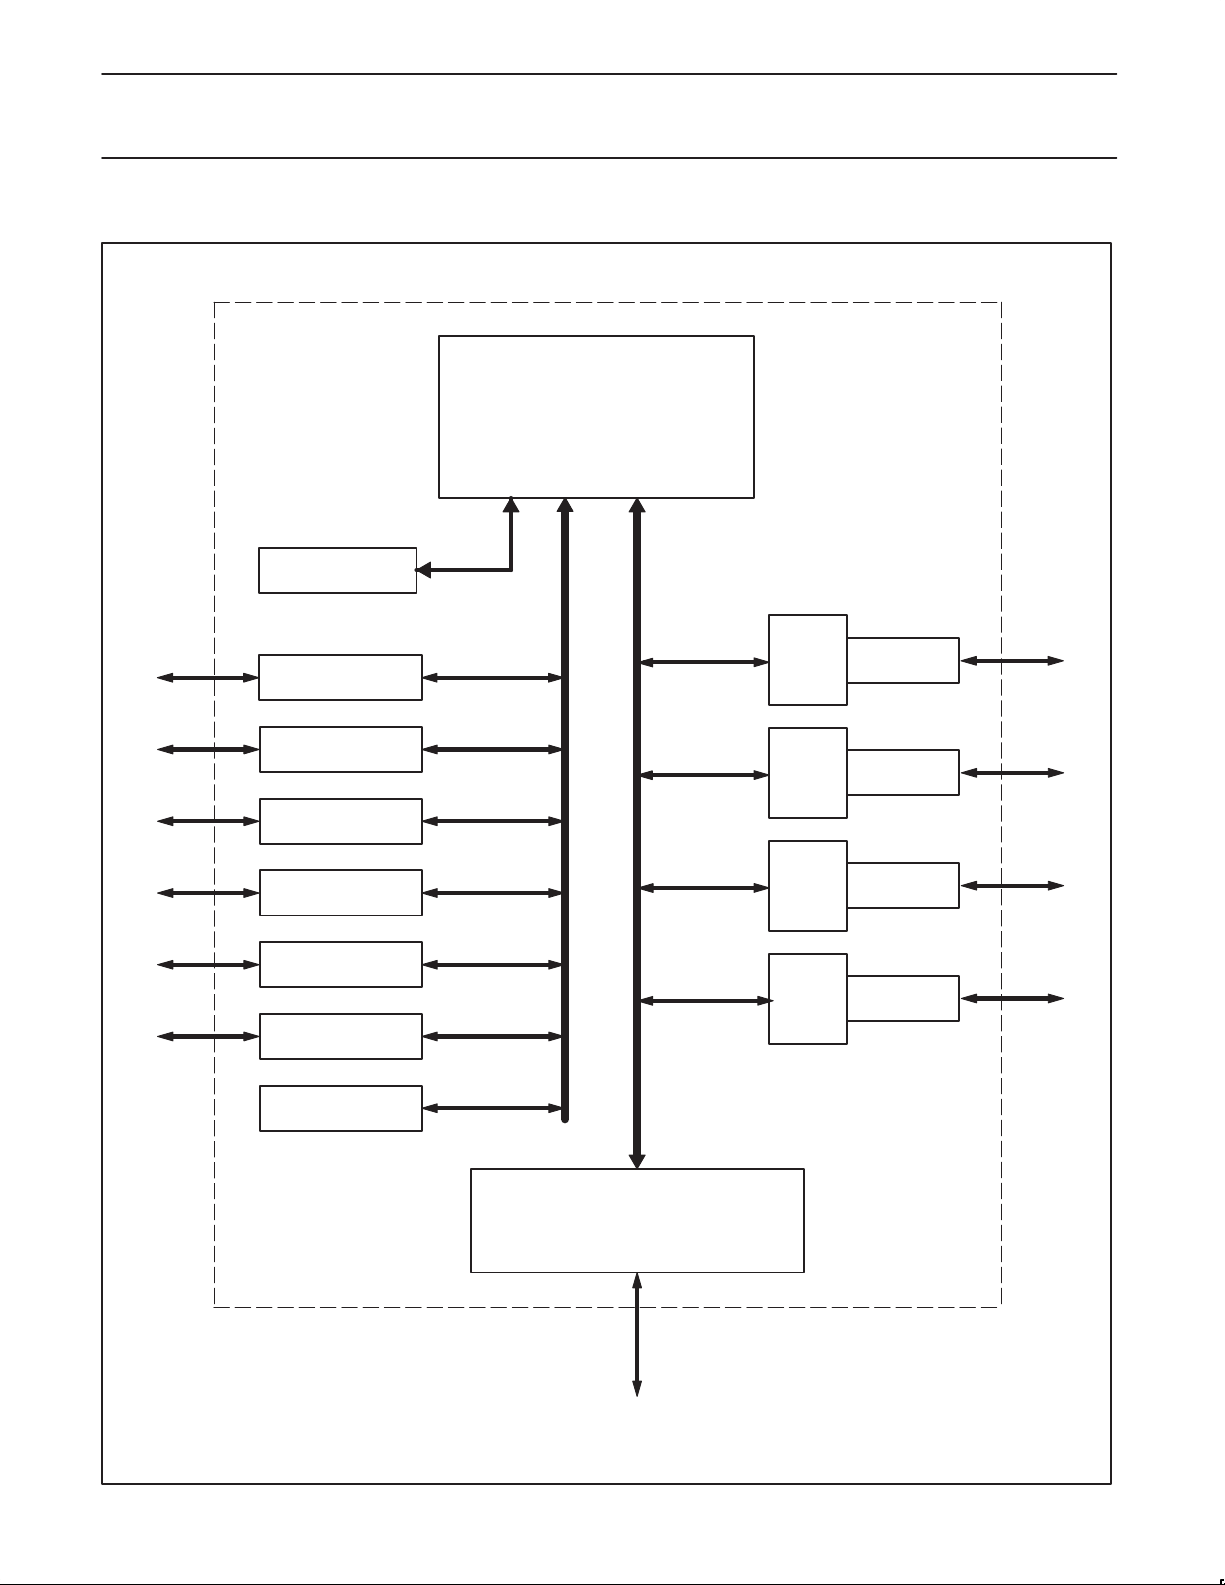
XA-H3 BLOCK DIAGRAM
XA-H3 CPU Core
256 Bytes Data
SRAM
Port 0
Port 1
Port 2
Port 3
Timer 0
Timer 1
Watchdog
Timer
Data
SFR Bus
MMR Bus
DMA R0
DMA T0
DMA R1
DMA T1
DMA R2
DMA T2
DMA R3
DMA T3
UART 0
UART 1
UART 2
UART 3
1999 Sep 24
Memory Bus Controller
6 Chip Selects
Dynamic Bus Sizing
Dynamic Bus Timing
External
System Bus
SU01247
5
Page 6

Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
XA-H3 MEMORY MAPS
FFFFFFh
6 MB *
Common Code
and Data Space
000000h
Unified Memory
(von Neuman architecture)
*In either memory architecture, the XA-H3 can support a maximum of
6 MB because each of six Chip Selects is capable of 1 MB each. In
Unified architecture, Code and Data can share the same physical
Memory Chip and address space.
Code Space + Data Space = 6 MB Maximum Total with 1 MB per Chip Select. Each CS
(and thus, 1 MB space) can support either Code or Data in Harvard architecture.
FFFFFFh
FFFFFFh
Dedicated
Code Space
Dedicated
Data Space
1999 Sep 24
000000h
Harvard Architecture
000000h
SU01248
6
Page 7

Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
PIN DESCRIPTIONS
Mnemonic
V
SS
V
DD
ResetIn 55 I
WAIT/
Size16
XTALIn 60 I
XTALOut 61 I Crystal 2: Output from the oscillator amplifier.
CS0 49 O
CS1 48 O Chip Select 1*: Chip Selects 1 through 5 come out of reset disabled. They function as normal chip
CS2 47 O Chip Select 2 *: Active low Chip Selects CS1 through CS5 come out of reset disabled. They can
CS3 46 O Chip Select 3 *: See Chip Select 2 for description.
See Pins 56, 57 for 2 additional Chip Selects
WE 50 O Write Enable: Goes active low during all bus write cycles only.
OE 51 O Output Enable: Goes active low during all bus read cycles only.
BLE 54 O Byte Low Enable: Goes active low during all bus cycles that access data bus lines D7 – D0, read
BHE 53 O Byte High Enable: Goes active low during all bus cycles that access data bus lines D15 – D8,
ClkOut 45 O Clock Output: This pin outputs a buffered version of the internal CPU clock. The clock output may
A19 – A0 24 – 21,
D15 – D0 42 – 30,
P0.0 90 I/O P0.0_BRG0*: Port 0 Bit 0, or UART0 BRG output, or UART0 TxClk output 1
P0.1 91 I/O P0.1_RTS0: Port 0 Bit 1 , or UART0 RTS (Request T o Send) output. 1
P0.2 92 I/O P0.2_CTS0: Port 0 Bit 2, or UART0 CTS (Clear T o Send) input. 1
P0.3 93 I/O P0.3_CD0: Port 0 Bit 3, or UART0 Carrier Detect input. 1
P0.4 94 I/O P0.4_TRClk0: Port 0 Bit 4, or UART0 TR clock input. 1, 2
P0.5 95 I/O P0.5_RTClk0 : Port 0 Bit 5, or UART0 RT clock input. 1, 2
P0.6 99 I/O P0.6: Port 0 Bit 6 1
P0.7 100 I/O P0.7: Port 0 Bit 7 1
TxD0 96 O TxD0: Transmit data for UART0.
Lqfp
Pin No.
1, 19, 28,
44, 59,
76, 88
2, 20, 29,
43, 62,
77, 89
52 I
18 – 3
27 – 25
Type Name and Function
Ground: 0 V reference.
I
Power Supply: This is the power supply voltage for normal, idle, and power down operation.
I
Reset: A low on this pin resets the microcontroller, causing I/O ports and peripherals to take on
their default states, and the processor to begin execution at the address contained in the reset
vector.
Wait/Size16: During Reset, this input determines bus size for boot device (“1” = 16-bit boot device;
“0” = 8-bit.) During normal operation this is the Wait input (“1” = Wait; “0” = Proceed.)
Crystal 1: Input to the inverting amplifier used in the oscillator circuit and input to the internal clock
generator circuits.
Chip Select 0: This output provides the active low chip select to the boot device (usually ROM or
Flash.) From reset, it is enabled and mapped to an address range based at 000000h. It can be
remapped by software to a higher base in the address map (see the “Memory Interface” chapter in
XA-H3 User Manual
the
selects on the H3. CS1 can be “swapped” with CS0 (see the SWAP operation in the “Memory
Controller” chapter of the
after the swap, but is capable of being based anywhere in the 16 MB address space.
be programmed to function as normal chip selects. CS2 through CS5 are not used with the
“SWAP” operation (only /CS0 and CS1 can be swapped; see “Memory Controller” chapter in the
XA-H3 User Manual
or write.
read or write. Never goes active on an 8-bit bus; always goes active on Reads or Fetches on a
16-bit bus, even if the processor does not need these bits. In other words, all Reads (byte or word)
on a 16-bit bus, assert BHE
be used in conjunction with the external bus to synchronize WAIT state generators, etc. The clock
output may be disabled by software. WARNING: The capacitive loading on this output must not
exceed 40 pf.
O Address[19:0]: These address lines output A19 – A0 during all external bus cycles.
I/O Data[15:0]: Bi-directional data bus, D15 – D0; for those bus cycles that are programmed to occur
on an “8-bit bus”, D15 – D8 are unused.
.)
XA-H3 User Manual
.) They are mappable to any region of the 16 MB address space.
.
.) CS1 is usually mapped to be based at 000000h
See
Note
1999 Sep 24
7
Page 8

Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
Mnemonic
RxD0 97 I RxD0: Receive data for UART0
GPOut 98 O GPOut – General Purpose Output Bar: Similar to GPIO, but Push/Pull and inverted output only.
P1.0 68 I/O P1.0_RxD2: Port 1 Bit 0, or UART2 RxD input
P1.1 69 I/O P1.1_TxD2: Port 1 Bit 1, or UART2 TxD output
P1.2 70 I/O P1.2_RTClk2 : Port 1 Bit 2, or UART2 RT Clock input 2
P1.3 71 I/O P1.3_TRClk2: Port 1 Bit 3, or UART2 TR Clock input 2
P1.4 72 I/O P1.4_CD2: Port 1 Bit 4, or UART2 Carrier Detect input
P1.5 73 I/O P1.5_CTS2: Port 1 Bit 5, or UART2 Clear T o Send input
P1.6 74 I/O P1.6_RTS2: Port 1 Bit 6, or UART2 Request T o Send output
P1.7 75 I/O P1.7_BRG2: Port 1 Bit 7, or BRG output, or TxClk output (see UART clk diagrams in the
P2.0 80 I/O P2.0_RxD3: Port 2 Bit 0, or UART3 Rx Data input
P2.1 81 I/O P2.1_TxD3: Port 2 Bit 1, or UART3 Tx Data output
P2.2 82 I/O P2.2_RTClk3 : Port 2 Bit 2, or UART3 RT Clock input 2
P2.3 83 I/O P2.3_ComClk_TRClk3: Port 2 Bit 3, or UART3 TR Clock input 2
P2.4 84 I/O P2.4_CD3: Port 2 Bit 4, or UART3 Carrier Detect input
P2.5 85 I/O P2.5_CTS3: Port 2 Bit 5, or UART3 Clear T o Send input
P2.6 86 I/O P2.6_RTS3: Port 2 Bit 6, or UART3 Request T o Send output
P2.7 87 I/O P2.7_BRG3: Port 2 Bit 7, or BRG output, or TxClk output (see UART clock diagrams in the
P3.0 56 I/O P3.0_CS4_RTClk1: Port 3 Bit 0, or CS4 output, or UART1 RT Clock input
P3.1 57 I/O
P3.2 58 I/O
P3.3 63 I/O P3.3_Timer1_BRG1: Port 3 Bit 3, or Timer1 input or output, or UART1 BRG output.
P3.4 64 I/O P3.4_CTS1: Port 3 Bit 4, or UART1 Clear T o Send input
P3.5 65 I/O P3.5_RxD1: Port 3 Bit 5, or UART1 Receive Data input
P3.6 66 I/O P3.6_TxD1: Port 3 Bit 6, or UART1 Transmit Data output
P3.7 67 I/O P3.7_Int1 _TRClk1: Port 3 Bit 7, or External Interrupt 1 input, or UART1 TR Clock input 2
CD1_Int2 78 I/O CD1_Int2: UART1 Carrier Detect, or External Interrupt 2
Int0 79 I/O External Interrupt 0
Lqfp
Pin No.
Name and FunctionType
WARNING: This output is inverted. The polarity of the pin is the opposite of the bit that drives it
(GPOut[7])
XA-H3
User Manual
.)
XA-H3
User Manual
Active low chip selects CS1 through CS5 come out of reset disabled. CS2 through CS5 are not
used with the “SWAP” operation (see “Memory Controller” chapter in the
They are mappable to any region of the 16 MB address space.
P3.1_CS5_RTS1: Port 3 Bit 1, or CS5 output, or UART1 Request To Send output
Active low chip selects CS1 through CS5 come out of reset disabled. CS2 through CS5 are not
used with the “SWAP” operation (see “Memory Controller” chapter in the
They are mappable to any region of the 16 MB address space.
P3.2_Timer0_ResetOut: Port 3 Bit 2, or Timer0 input or output, or ResetOut output.
ResetOut: If the ResetOut function is selected, this pin outputs a low whenever the XA-H3
processor is reset by an internal source (Watchdog Reset or the RESET instruction.)
WARNING: Unlike the other 31 GPIO pins, during power up reset, this pin can output a strongly
driven low pulse. The duration of this low pulse ranges from 0 ns to 258 system clocks, starting at
the time that VCC is valid. The state of the ResetIn
ResetIn
When used as GPIO, this pin can also be driven low by software without resetting the XA-H3.
.)
is not passed to ResetOut.
XA-H3 User Manual
XA-H3 User Manual
pin does not affect this pulse; in other words
.)
.)
See
Note
2
NOTES:
1. See
XA-H3 User Guide,
2. RTClk input is usually used for Rx Clock if an external clock is needed, but can be used for either Rx or Tx or both. TRClk is usually used for
Tx Clock, but can be used for Rx or Tx or both.
1999 Sep 24
“Pins Chapter,” for how to program selection of pin functions.
8
Page 9

Philips Semiconductors Preliminary specification
writing BTRL
40h in that order. Follow these two writes with five NOPS. This is
XA-H3CMOS 16-bit highly integrated microcontroller
CONTROL REGISTER OVERVIEW
There are two types of control registers in the XA-H3, these are SFRs
(Special Function Registers), and MMRs (Memory Mapped Registers.)
The SFR registers, with the exception of MRBL, MRBH, MICFG, BCR,
BRTH, BRTL, and RSTSRC are the standard XA core registers. See
WARNINGs about BCR, BRTH, and BRTL in Table 2.
SFRs are accessed by “direct addressing” only (see
Manual
for direct addressing.) The MMRs are specific to the XA-H3
IC25 XA User
Table 2. Special Function Registers (SFR)
Name Description
BCR Bus Configuration Reg
RESERVED – see
Warning
BTRH Bus Timing Reg High 469h
BTRL Bus Timing Reg Low 468h
SFR
Address
46Ah WARNING – Never write to the BCR register in the XA-H3 – it is initialized to 07h,
MSB LSB
the only legal value. This is not the same as for some other XA derivatives.
WARNING – Immediately after reset, always write BTRH = 51h, followed by
=
not the same as for some other XA derivatives.
on-chip peripherals, and can be accessed by any addressing mode
that can be used for off-chip data accesses. The MMRs are
implemented in a relocatable block. See the “Memory Controller”
chapter in the
MMRs by writing a new base address into the MRBL and MRBH
(MMR Base Low and High) registers.
Bit Functions and Addresses
XA-H3 User Manual
for details on how to relocate the
Reset
Value
07h
FFh
EFh
MRBL# MMR Base Address Low 496h MA15 MA14 MA13 MA12 – – – MRBE x0h
MRBH# MMR Base Address High 497h MA23 MA22 MA21 MA20 MA19 MA18 MA17 MA16 xx
MICFG# ClkOut Tri-St Enable
1 = Enabled
CS Code Segment 443h 00h
DS Data Segment 441h 00h
ES Extra Segment 442h 00h
IEH* Interrupt Enable High 427h
IEL* Interrupt Enable Low 426h EA EDMAH EDMAL EX2 ET1 EX1 ET0 EX0 00h
IPA0 Interrupt Priority A0 4A0h – PT0 – PX0 00h
IPA1 Interrupt Priority A1 4A1h – PT1 – PX1 00h
IPA2 Interrupt Priority A2 4A2h – PDMAL – PX2 00h
IPA3 Interrupt Priority A3 4A3h Reserved – PDMAH 00h
IPA4 Interrupt Priority A4 4A4h – PSC23 – PSC01 00h
IPA5 Interrupt Priority A5 4A5h – – – PAutoB 00h
IPA6 Interrupt Priority A6 4A6h – PHSWR1 – PHSWR0 00h
IPA7 Interrupt Priority A7 4A7h – PHSWR3 – PHSWR2 00h
499h – – – – – – – CLKOE 01h
33F 33E 33D 33C 33B 33A 339 338
EHSWR3 EHSWR2 EHSWR1 EHSWR0 – EAuto ESC23 ESC01
337 336 335 334 333 332 331 330
00h
387 386 385 384 383 382 381 380
P0* Port 0 430h FFh
38F 38E 38D 38C 38B 38A 389 388
P1* Port 1 431h FFh
397 396 395 394 393 392 391 390
P2* Port 2 432h FFh
39F 39E 39D 39C 39B 39A 399 398
P3* Port 3 433h FFh
1999 Sep 24
9
Page 10
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
Name
P0CFGA Port 0 Configuration A 470h 5
P1CFGA Port 1 Configuration A 471h 5
P2CFGA Port 2 Configuration A 472h 5
P3CFGA Port 3 Configuration A 473h 5
P0CFGB Port 0 Configuration B 4F0h 5
P1CFGB Port 1 Configuration B 4F1h 5
P2CFGB Port 2 Configuration B 4F2h 5
P3CFGB Port 3 Configuration B 4F3h 5
PCON* Power Control Reg 404h – – – – – – PD IDL 00h
PSWH* Program Status Word High 401h SM TM RS1 RS0 IM3 IM2 IM1 IM0 2
PSWL* Program Status Word Low 400h C AC – – – V N Z 2
PSW51* 80C51 Compatible PSW 402h C AC F0 RS1 RS0 V F1 P 3
Description
SFR
Address
MSB LSB
227 226 225 224 223 222 221 220
20F 20E 20D 20C 20B 20A 209 208
207 206 205 204 203 202 201 200
217 216 215 214 213 212 211 210
Bit Functions and Addresses
Reset
Value
RSTSRC Reset Source Reg 463h ROEN – – – – R_WD R_CMD R_EXT 7
RTH0 Timer 0 Reload High 455h 00h
RTH1 Timer 1 Reload High 457h 00h
RTL0 Timer 0 Reload Low 454h 00h
RTL1 Timer 1 Reload Low 456h 00h
SCR System Configuration Reg 440h – – – – PT1 PT0 CM PZ 00h
21F 21E 21D 21C 21B 21A 219 218
SSEL* Segment Selection Reg 403h ESWEN R6SEG R5SEG R4SEG R3SEG R2SEG R1SEG R0SEG 00h
SWE Software Interrupt Enable 47Ah – SWE7 SWE6 SWE5 SWE4 SWE3 SWE2 SWE1 00h
357 356 355 354 353 352 351 350
SWR* 42Ah – SWR7 SWR6 SWR5 SWR4 SWR3 SWR2 SWR1 00h
287 286 285 284 283 282 281 280
TCON* Timer 0/1 Control 410h TF1 TR1 TF0 TR0 IE1 IT1 IE0 IT0 00h
TH0 Timer 0 High 451h 00h
TH1 Timer 1 High 453h 00h
TL0 Timer 0 Low 450h 00h
TL1 Timer 1 Low 452h 00h
TMOD Timer 0/1 Mode 45Ch GATE C/T M1 M0 GATE C/T M1 M0 00h
1999 Sep 24
10
Page 11

Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
Name
TSTAT* Timer 0/1 Extended Status 411h – – – – – T1OE – T0OE 00h
WDCON* Watchdog Control 41Fh PRE2 PRE1 PRE0 – – WDRUN WDTOF – 6
WDL W atchdog Timer Reload 45Fh 00h
WFEED1 Watchdog Feed 1 45Dh x
WFEED2 Watchdog Feed 2 45Eh x
NOTES:
* SFRs marked with an asterisk (*) are bit addressable.
# SFRs marked with a pound sign (#) are additional SFR registers specific to the XA-H3 and XA-H4.
1. The XA-H3 implements an 8-bit SFR bus, as stated in Chapter 8 of the
8-bit operations. Attempts to write 16 bits to an SFR will actually write only the lower 8 bits. 16-bit SFR reads will return undefined data in the
upper byte.
2. SFR is loaded from the reset vector.
3. F1, F0, and P reset to “0”. All other bits are loaded from the reset vector.
4. Unimplemented bits in SFRs are “X” (unknown) at all times. “1”s should not be written to these bits since they may be used for other
purposes in future XA derivatives. The reset value shown for these bits is “0”.
5. Port configurations default to quasi-bidirectional when the XA begins execution after reset. Thus all PnCFGA registers will contain FFh and
PnCFGB register will contain 00h. See warning in
up. Basically, during this period, this pin may output a strongly-driven low pulse. If the pulse does occur, it will terminate in a transition to high
at a time no later than the 259th system clock after valid V
6. The WDCON reset value is E6 for a Watchdog reset; E4 for all other reset causes.
7. The RSTSRC register reflects the cause of the last XA reset. One bit will be set to “1”, the others will be “0”. RSTSRC[7] enables the ResetOut
function; “1” = Enabled, “0” = Disabled. See
8. The XA guards writes to certain bits (typically interrupt flags) that may be written by a peripheral function. This prevents loss of an interrupt or
other status if a bit was written directly by a peripheral action between the read and write of an instruction that performs a read-modify-write
operation. XA-H3 SFR bits that are guarded in this manner are: TF1, TF0, IE1, and IE0 (in TCON), and WDTOF (in WDCON).
Description
SFR
Address
XA-H3 User Manual
XA-H3 User Manual
MSB LSB
28F 28E 28D 28C 28B 28A 289 288
2FF 2FE 2FD 2FC 2FB 2FA 2F9 2F8
power up.
CC
for details; RSTSRC[7] differs in function from most other XA derivatives.
Bit Functions and Addresses
IC25 Data Handbook XA User Guide
about P3.2_Timer0_ResetOut pin during first 258 clocks after power
. All SFR accesses must be
Reset
Value
1999 Sep 24
11
Page 12
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
Table 3. Memory Mapped Registers (MMR)
MMR Name
UART0 Write Register 0 R/W 8 800h Command register 00h
UART0 Write Register 1 R/W 8 802h Tx/Rx Interrupt & data transfer mode xx
UART0 Write Register 2 R/W 8 804h Extended Features Control xx
UART0 Write Register 3 R/W 8 806h Receive Parameter and Control 00h
UART0 Write Register 4 R/W 8 808h Tx/Rx miscellaneous parameters & mode 00h
UART0 Write Register 5 R/W 8 80Ah Tx parameter and control 00h
Reserved – do not write 8 80Ch Reserved – do not write 00h
Reserved – do not write 8 80Eh Reserved – do not write xx
UART0 Write Register 8 R/W 8 810h Transmit Data Buffer xx
UART0 Write Register 9 R/W 8 812h Master Interrupt control xx
UART0 Write Register 10 R/W 8 814h Miscellaneous Tx/Rx control register 00h
UART0 Write Register 11 R/W 8 816h Clock Mode Control xx
UART0 Write Register 12 R/W 8 818h Lower Byte of Baud rate time constant 00h
UART0 Write Register 13 R/W 8 81Ah Upper Byte of Baud rate time constant 00h
UART0 Write Register 14 R/W 8 81Ch Miscellaneous Control bits xx
UART0 Write Register 15 R/W 8 81Eh External / Status interrupt control f8h
Reserved – do not write 8 828h Reserved – do not write 00h
Reserved – do not write 8 82Ah Reserved – do not write 00h
UART0 Read Register 0 RO 8 820h Tx/Rx buffer and external status
UART0 Read Register 1 RO 8 822h Receive condition status
Reserved – do not write 824h –
UART0 Read Register 3 RO 8 826h Interrupt Pending Bits
Reserved – do not write 8 82Ch Reserved – do not write
Reserved – do not write 8 82Eh Reserved – do not write
UART0 Read Register 8 RO 8 830h Receive Buffer
Reserved – do not write 832h
UART0 Read Register 10 RO 8 834h Clock status
Reserved – do not write 836-83Eh –
UART1 Write Register 0 R/W 8 840h Command register 00h
UART1 Write Register 1 R/W 8 842h Tx/Rx Interrupt & data transfer mode xx
UART1 Write Register 2 R/W 8 844h Extended Features Control xx
UART1 Write Register 3 R/W 8 846h Receive Parameter and Control 00h
UART1 Write Register 4 R/W 8 848h Tx/Rx miscellaneous parameters & mode 00h
UART1 Write Register 5 R/W 8 84Ah Tx. parameter and control 00h
Reserved – do not write 8 84Ch Reserved – do not write 00h
Reserved – do not write 8 84Eh Reserved – do not write xx
UART1 Write Register 8 R/W 8 850h Transmit Data Buffer xx
UART1 Write Register 9 R/W 8 852h Master Interrupt control xx
UART1 Write Register 10 R/W 8 854h Miscellaneous Tx/Rx control register 00h
UART1 Write Register 11 R/W 8 856h Clock Mode Control xx
UART1 Write Register 12 R/W 8 858h Lower Byte of Baud rate time constant 00h
UART1 Write Register 13 R/W 8 85Ah Upper Byte of Baud rate time constant 00h
Read/Write or
Read Only
UART0 Registers
UART1 Registers
Size
Address
Offset
Description
Reset
Value
1999 Sep 24
12
Page 13
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
MMR Name
UART1 Write Register 14 R/W 8 85Ch Miscellaneous Control bits xx
UART1 Write Register 15 R/W 8 85Eh External / Status interrupt control f8h
Reserved – do not write 8 868h Reserved – do not write 00h
Reserved – do not write 8 86Ah Reserved – do not write 00h
UART1 Read Register 0 RO 8 860h Tx/Rx buffer and external status
UART1 Read Register 1 RO 8 862h Receive condition status
Reserved – do not write 864h
UART1 Read Register 3 RO 8 866 Interrupt Pending Bits
Reserved – do not write 8 86Ch Reserved – do not write
Reserved – do not write 8 86Eh Reserved – do not write
UART1 Read Register 8 RO 8 870h Receive Buffer
Reserved – do not write 872h
UART1 Read Register 10 RO 8 874h Clock status
Reserved – do not write 876-87Eh
UART2 Write Register 0 R/W 8 880h Command register 00h
UART2 Write Register 1 R/W 8 882h Tx/Rx Interrupt & data transfer mode xx
UART2 Write Register 2 R/W 8 884h Extended Features Control xx
UART2 Write Register 3 R/W 8 886h Receive Parameter and Control 00h
UART2 Write Register 4 R/W 8 888h Tx/Rx miscellaneous parameters & mode 00h
UART2 Write Register 5 R/W 8 88Ah Tx. parameter and control 00h
Reserved – do not write 8 88Ch Reserved – do not write 00h
Reserved – do not write 8 88Eh Reserved – do not write xx
UART2 Write Register 8 R/W 8 890h Transmit Data Buffer xx
UART2 Write Register 9 R/W 8 892h Master Interrupt control xx
UART2 Write Register 10 R/W 8 894h Miscellaneous Tx/Rx control register 00h
UART2 Write Register 11 R/W 8 896h Clock Mode Control xx
UART2 Write Register 12 R/W 8 898h Lower Byte of Baud rate time constant 00h
UART2 Write Register 13 R/W 8 89Ah Upper Byte of Baud rate time constant 00h
UART2 Write Register 14 R/W 8 89Ch Miscellaneous Control bits xx
UART2 Write Register 15 R/W 8 89Eh External / Status interrupt control f8h
Reserved – do not write 8 8A8h Reserved – do not write 00h
Reserved – do not write 8 8AAh Reserved – do not write 00h
UART2 Read Register 0 RO 8 8A0h Tx/Rx buffer and external status
UART2 Read Register 1 RO 8 8A2h Receive condition status
Reserved – do not write 8A4h
UART2 Read Register 3 RO 8 8A6h Interrupt Pending Bits
Reserved – do not write 8 8ACh Reserved – do not write
Reserved – do not write 8 8AEh Reserved – do not write
UART2 Read Register 8 RO 8 8B0h Receive Buffer
Reserved – do not write 8B2h
UART2 Read Register 10 RO 8 8B4h Clock status
Reserved – do not write 8B6-8BEh
Read/Write or
Read Only
UART2 Registers
Size
Address
Offset
Description
Reset
Value
1999 Sep 24
13
Page 14
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
MMR Name
UART3 Write Register 0 R/W 8 8C0h Command register 00h
UART3 Write Register 1 R/W 8 8C2h Tx/Rx Interrupt & data transfer mode xx
UART3 Write Register 2 R/W 8 8C4h Extended Features Control xx
UART3 Write Register 3 R/W 8 8C6h Receive Parameter and Control 00h
UART3 Write Register 4 R/W 8 8C8h Tx/Rx miscellaneous parameters & mode 00h
UART3 Write Register 5 R/W 8 8CAh Tx. parameter and control 00h
Reserved – do not write 8 8CCh Reserved – do not write 00h
Reserved – do not write 8 8CEh Reserved – do not write xx
UART3 Write Register 8 R/W 8 8D0h Transmit Data Buffer xx
UART3 Write Register 9 R/W 8 8D2h Master Interrupt control xx
UART3 Write Register 10 R/W 8 8D4h Miscellaneous Tx/Rx control register 00h
UART3 Write Register 11 R/W 8 8D6h Clock Mode Control xx
UART3 Write Register 12 R/W 8 8D8h Lower Byte of Baud rate time constant 00h
UART3 Write Register 13 R/W 8 8DAh Upper Byte of Baud rate time constant 00h
UART3 Write Register 14 R/W 8 8DCh Miscellaneous Control bits xx
UART3 Write Register 15 R/W 8 8DEh External / Status interrupt control f8h
Reserved – do not write 8 8E8h Reserved – do not write 00h
Reserved – do not write 8 8EAh Reserved – do not write 00h
UART3 Read Register 0 RO 8 8E0h Tx/Rx buffer and external status
UART3 Read Register 1 RO 8 8E2h Receive condition status
Reserved – do not write 8E4h
UART3 Read Register 3 RO 8 8E6h Interrupt Pending Bits
Reserved – do not write 8 8ECh Reserved – do not write
Reserved – do not write 8 8EEh Reserved – do not write
UART3 Read Register 8 RO 8 8F0h Receive Buffer
Reserved – do not write 8F2h –
UART3 Read Register 10 RO 8 8F4h Clock status
Reserved – do not write 8F6-8FEh
DMA Control Register Ch.0 Rx R/W 8 100h Control Register 00h
FIFO Control & Status Reg Ch.0 Rx R/W 8 101h Control & Status Register 00h
Segment Register Ch.0 Rx R/W 8 102h Points to 64 k data segment 00h
Buffer Base Register Ch.0 Rx R/W 8 104h Wrap Reload Value for A15 – A8, A7 – A0
Buffer Bound Register Ch.0 Rx R/W 16 106h Upper Bound (plus 1) on A15 – A0 0000h
Address Pointer Reg Ch.0 Rx R/W 16 108h Current Address pointer A15 – A0 0000h
Byte Count Register Ch.0 Rx R/W 16 10Ah Corresponds to A15 – A0 Byte Count, generates
Data FIFO Register Ch.0 Lo Rx R/W 16 10Ch 10Ch = Byte 0 = older,
Data FIFO Register Ch.0 Hi Rx R/W 16 10Eh 10Eh = Byte 2 = older,
DMA Control Register Ch.1 Rx R/W 8 110h Control Register 00h
FIFO Control & Status Register Ch.1 Rx R/W 8 111h Control & Status Register 00h
Segment Register Ch. 1 Rx R/W 8 112h Points to 64 k data segment 00h
Read/Write or
Read Only
UART3 Registers
Rx DMA Registers
Size
Address
Offset
Description
reloaded to zero by hardware
interrupt if enabled and byte count exceeded.
10Dh = Byte 1 = younger
10Fh = Byte 3 = younger
Reset
Value
00h
0000h
00h
00h
00h
00h
1999 Sep 24
14
Page 15
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
MMR Name
Buffer Base Register Ch. 1 Rx R/W 8 114h Wrap Reload Value for A15 – A8, A7 – A0
Buffer Bound Register Ch.1 Rx R/W 16 116h Upper Bound (plus 1) on A15 – A0 0000h
Address Pointer Reg Ch.1 Rx R/W 16 1 18h Current Address pointer A15 – A0 0000h
Byte Count Register Ch.1 Rx R/W 16 11Ah Corresponds to A15 – A0 Byte Count, generates
Data FIFO Register Ch.1 Lo Rx R/W 16 11Ch 11Ch = Byte 0 = older,
Data FIFO Register Ch.1 Hi Rx R/W 16 11Eh 11Eh = Byte 2 = older,
DMA Control Register Ch.2 Rx R/W 8 120h Control Register 00h
FIFO Control & Status Register Ch.2 Rx R/W 8 121h Control & Status Register 00h
Segment Register Ch. 2 Rx R/W 8 122h Points to 64 k data segment 00h
Buffer Base Register Ch. 2 Rx R/W 8 124h Wrap Reload Value for A15 – A8, A7 – A0
Buffer Bound Register Ch.2 Rx R/W 16 126h Upper Bound (plus 1) on A15 – A0 0000h
Address Pointer Reg Ch.2 Rx R/W 16 128h Current Address pointer A15 – A0 0000h
Byte Count Register Ch.2 Rx R/W 16 12Ah Corresponds to A15 – A0 Byte Count, generates
Data FIFO Register Ch.2 Lo Rx R/W 16 12Ch 12Ch = Byte 0 = older,
Data FIFO Register Ch.2 Hi Rx R/W 16 12Eh 12Eh = Byte 2 = older,
DMA Control Register Ch.3 Rx R/W 8 130h Control Register 00h
FIFO Control & Status Register Ch.3 Rx R/W 8 131h Control & Status Register 00h
Segment Register Ch. 3 Rx R/W 8 132h Points to 64 k data segment 00h
Buffer Base Register Ch. 3 Rx R/W 8 134h Wrap Reload Value for A15 – A8, A7 – A0
Buffer Bound Register Ch.3 Rx R/W 16 136h Upper Bound (plus 1) on A15 – A0 0000h
Address Pointer Reg Ch.3 Rx R/W 16 138h Current Address pointer A15 – A0 0000h
Byte Count Register Ch.3 Rx R/W 16 13Ah Corresponds to A15 – A0 Byte Count, generates
Data FIFO Register Ch.3 Lo Rx R/W 16 13Ch 13Ch = Byte 0 = older,
Data FIFO Register Ch.3 Hi Rx R/W 16 13Eh 13Eh = Byte 2 = older,
DMA Control Register Ch.0 Tx R/W 8 140h Control Register 00h
FIFO Control & Status Register Ch.0 Tx R/W 8 141h Control & Status Register 00h
Segment Register Ch. 0 Tx R/W 8 142h Points to 64 k data segment 00h
Buffer Base Register Ch. 0 Tx R/W 8 144h Wrap Reload Value for A15 – A8, A7 – A0
Buffer Bound Register Ch.0 Tx R/W 16 146h Upper Bound (plus 1) on A15 – A0 0000h
Address Pointer Reg Ch.0 Tx R/W 16 148h Current Address pointer A15 – A0 0000h
Byte Count Register Ch.0 Tx R/W 16 14Ah Corresponds to A15 – A0 Byte Count, generates
Data FIFO Register Ch.0 Tx R/W 16 14Ch 14C = Byte0 = older
Read/Write or
Read Only
Tx DMA Registers
Size
Address
Offset
Description
reloaded to zero by hardware
interrupt if enabled and byte count exceeded.
11Dh = Byte 1 = younger
11Fh = Byte 3 = younger
reloaded to zero by hardware
interrupt if enabled and byte count exceeded.
12Dh = Byte 1 = younger
12Fh = Byte 3 = younger
reloaded to zero by hardware
interrupt if enabled and byte count exceeded.
13Dh = Byte 1 = younger
13Fh = Byte 3 = younger
reloaded to zero by hardware
interrupt if enabled and byte count exceeded.
14D = Byte 1 = younger
Reset
Value
00h
0000h
00h
00h
00h
00h
00h
0000h
00h
00h
00h
00h
00h
0000h
00h
00h
00h
00h
00h
0000h
0000h
1999 Sep 24
15
Page 16
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
MMR Name
Data FIFO Register Ch.0 Tx R/W 16 14Eh 14E = Byte2 = older
DMA Control Register Ch.1 Tx R/W 8 150h Control Register 00h
FIFO Control & Status Register Ch.1 Tx R/W 8 151h Control & Status Register 00h
Segment Register Ch.1 Tx R/W 8 152h Points to 64 k data segment 00h
Buffer Base Register Ch.1 Tx R/W 8 154h Wrap Reload Value for A15 – A8, A7 – A0
Buffer Bound Register Ch.1 Tx R/W 16 156h Upper Bound (plus 1) on A15 – A0 0000h
Address Pointer Reg Ch.1 Tx R/W 16 158h Current Address pointer A15 – A0 0000h
Byte Count Register Ch.1 Tx R/W 16 15Ah Corresponds to A15 – A0 Byte Count, generates
Data FIFO Register Ch.1 Lo Tx R/W 16 15Ch Byte0 & 1 0000h
Data FIFO Register Ch.1 Hi Tx R/W 16 15Eh Byte2 & 3 0000h
DMA Control Register Ch.2 Tx R/W 8 160h Control Register 00h
FIFO Control & Status Register Ch.2 Tx R/W 8 161h Control & Status Register 00h
Segment Register Ch.2 Tx R/W 8 162h Points to 64 k data segment 00h
Buffer Base Register Ch.2 Tx R/W 8 164h Wrap Reload Value for A15 – A8, A7 – A0
Buffer Bound Register Ch.2 Tx R/W 16 166h Upper Bound (plus 1) on A15 – A0 0000h
Address Pointer Reg Ch.2 Tx R/W 16 168h Current Address pointer A15 – A0 0000h
Byte Count Register Ch.2 Tx R/W 16 16Ah Corresponds to A15 – A0 Byte Count, generates
Data FIFO Register Ch.2 Lo Tx R/W 16 16Ch Byte0 & 1 0000h
Data FIFO Register Ch.2 Hi Tx R/W 16 16Eh Byte2 & 3 0000h
DMA Control Register Ch.3 Tx R/W 8 170h Control Register 00h
FIFO Control & Status Register Ch.3 Tx R/W 8 171h Control & Status Register 00h
Segment Register Ch. 3 Tx R/W 8 172h Points to 64 k data segment 00h
Buffer Base Register Ch. 3 Tx R/W 8 174h Wrap Reload Value for A15 – A8,
Buffer Bound Register Ch.3 Tx R/W 16 176h Upper Bound (plus 1) on A15 – A0 0000h
Address Pointer Reg Ch.3 Tx R/W 16 178h Current Address pointer A15 – A0 0000h
Byte Count Register Ch.3 Tx R/W 16 17Ah Corresponds to A15 – A0 Byte Count, generates
Data FIFO Register Ch.3Lo Tx R/W 16 17Ch Byte0 & 1 0000h
Data FIFO Register Ch.3 Hi Tx R/W 16 17Eh Byte2 & 3 0000h
Rx Character Time Out Register Ch.0 R/W 8 200h 0 value disables counter interrupt. 00h
Rx Character Time Out Register Ch.1 R/W 8 202h Same as above, for Rx1 00h
Rx Character Time Out Register Ch.2 R/W 8 204h Same as above, for Rx2 00h
Rx Character Time Out Register Ch.3 R/W 8 206h Same as above, for Rx3 00h
Global DMA Interrupt Register R/W 16 210h DMA Interrupt Flags 0000h
GPOut R/W 8 260h GPOut[7] drives pin 98 (GPOut) through an
Read/Write or
Read Only
R/W 180-1FEh RESERVED for future DMA –
Miscellaneous DMA Registers
Size
Address
Offset
Description
14F = Byte3 = younger
reloaded to zero by hardware
interrupt if enabled and byte count exceeded.
reloaded to zero by hardware
interrupt if enabled and byte count exceeded.
A7 – A0 reloaded to zero by hardware
interrupt if enabled and byte count exceeded.
inverter.
GPOut[6-0] are unused, and must be written
with zeroes.
Reset
Value
0000h
00h
0000h
00h
0000h
00h
0000h
8xh
1999 Sep 24
16
Page 17
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
MMR Name
Read/Write or
Read Only
Size
Address
Offset
Description
Reset
Value
Memory Interface (MIF) Registers
B0CFG R/W 8 280h MIF Bank 0 Config 0Fh
B0AM R/W 8 281h MIF Bank 0 Base Address 00h
B0TMG R/W 8 282h MIF Bank 0 Timing Params
B1CFG R/W 8 284h MIF Bank 1 Config
B1AM R/W 8 285h MIF Bank 1 Base Address
B1TMG R/W 8 286h MIF Bank 1 Timing Params
B2CFG R/W 8 288h MIF Bank 2 Config
B2AM R/W 8 289h MIF Bank 2 Base Address
B2TMG R/W 8 28Ah MIF Bank 2 Timing Params
B3CFG R/W 8 28Ch MIF Bank 3 Config
B3AM R/W 8 28Dh MIF Bank 3 Base Address
B3TMG R/W 8 28Eh MIF Bank 3 Timing Params
B4CFG R/W 8 290h MIF Bank 4 Config
B4AM R/W 8 291h MIF Bank 4 Base Address
B4TMG R/W 8 292h MIF Bank 4 Timing Params
B5CFG R/W 8 294h MIF Bank 5 Config
B5AM R/W 8 295h MIF Bank 5 Base Address
B5TMG R/W 8 296h MIF Bank 5 Timing Params
MBCL R/W 8 2BEh MIF Memory Bank Configuration Lock Register
Reserved – do not write R/W 8 2BFh Reserved – do not write
Miscellaneous Registers
Hi-Pri Soft Ints & Pin Mux Control Reg. R/W 16 2D0h Control bits for Hi-Priority Soft Ints, and Pin Mux 0000h
XInt2 R/W 8 2D2h External Interrupt 2 Control 00h
FUNCTIONAL DESCRIPTION
The XA-H3 functions are described in the following sections.
Because all blocks are thoroughly documented in either the
, or the
Data Handbook
XA-H3 User Manual
, only brief descriptions
IC25 XA
are given in this datasheet, in conjunction with references to the
appropriate document.
XA CPU
The CPU is a 30 MHz implementation of the standard XA CPU core.
See the
XA Data Handbook
(IC25) for details. The CPU core is
identical to the G3 core. See caveat in next paragraph about the Bus
Interface Unit.
Bus Interface Unit (BIU)
This is the internal Bus, not the bus at the pins. This internal bus
connects the CPU to Memory Controller.
WARNING: Immediately after reset, always write BTRH = 51h,
followed by BTRL = 40h, in that order. Once written, do not change
the values in these registers. Follow these two writes with five
NOPS. Never write to the BCR register, it comes out of reset
initialized to 07h, which is the only value that will work.
1999 Sep 24
17
XA CPU
BIU
Internal Cpu Bus
External
Memory
and I/O Bus
Memory
Controller
Figure 1. XA CPU Core BIU (Bus Interface Unit)
DMA
Channels
x8
SU01236
Page 18
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
Timers 0 and 1
Timers 0 and 1 are the standard XA-G3 timer 0 and 1. Each has an
associated I/O pin and interrupt. See the XA-G3 data sheet in the
IC25 XA Data Handbook
standard XA Timer 2. The Timer 2 block has been removed in order
to provide other functions on the XA-H3.
for details. Many XA derivatives include a
Watchdog Timer
This timer is a standard XA-G3 Watchdog Timer. See the G3
datasheet in IC25. Also, if you intend to use the Watchdog Timer to
assert the ResetOut
The Watchdog Timer is enabled at reset, and must be periodically
fed to prevent timeout. If the watchdog times out, it will generate an
internal reset; and if ResetOut
generate a ResetOut pulse (active low pulse on ResetOut
pin, see “ResetOut” in the
is enabled the internal reset will
XA-H3 User Manual
pin.)
Reset
On the XA-H3 there are two pins associated with reset. The ResetIn
pin provides an external reset into the XA-H3. The port pin
P3.2_Timer0_ResetOut
Because ResetOut
be tied directly back into the ResetIn
logic. This configuration will make all resets (internal or external)
appear to the XA as external resets. See the
a full discussion of the reset functions.
output can be configured as ResetOut.
does not reflect ResetIn, the ResetOut pin can
pin without other PC board
XA-H3 User Manual
for
ResetIn
The ResetIn function is the standard XA-G3 ResetIn function. The
ResetIn
signal does NOT get passed on to ResetOut. See the
XA-H3 User Manual
for details on reset.
ResetOut
The P3.2_Timer0_ResetOut pin provides an external indication (if the
ResetOut
low output when an internal reset occurs (internal reset is Reset
instruction or Watchdog time out.) If the ResetOut
the ResetOut
the Reset instruction is executed. This signal may be used to inform
other devices in the system that the XA-H3 has been internally reset.
The ResetIn
activated, the duration of the ResetOut
.
WARNING: At power on time, from the time that power coming up is
valid, the P3.2_Timer0_ResetOut pin may be driven low for any
period from zero nanoseconds up to 258 system clocks. This is true
independently of whether ResetIn
function is enabled in the RSRSRC register) via an active
function is enabled,
pin will be driven low when a Watchdog reset occurs or
signal does NOT get passed on to ResetOut. When
pulse is 256 system clocks.
is active or not.
Reset Source Register
The reset source identification register (RSTSRC) indicates the cause
of the most recent XA reset. The cause may have been an externally
applied reset signal, execution of the RESET instruction, or a
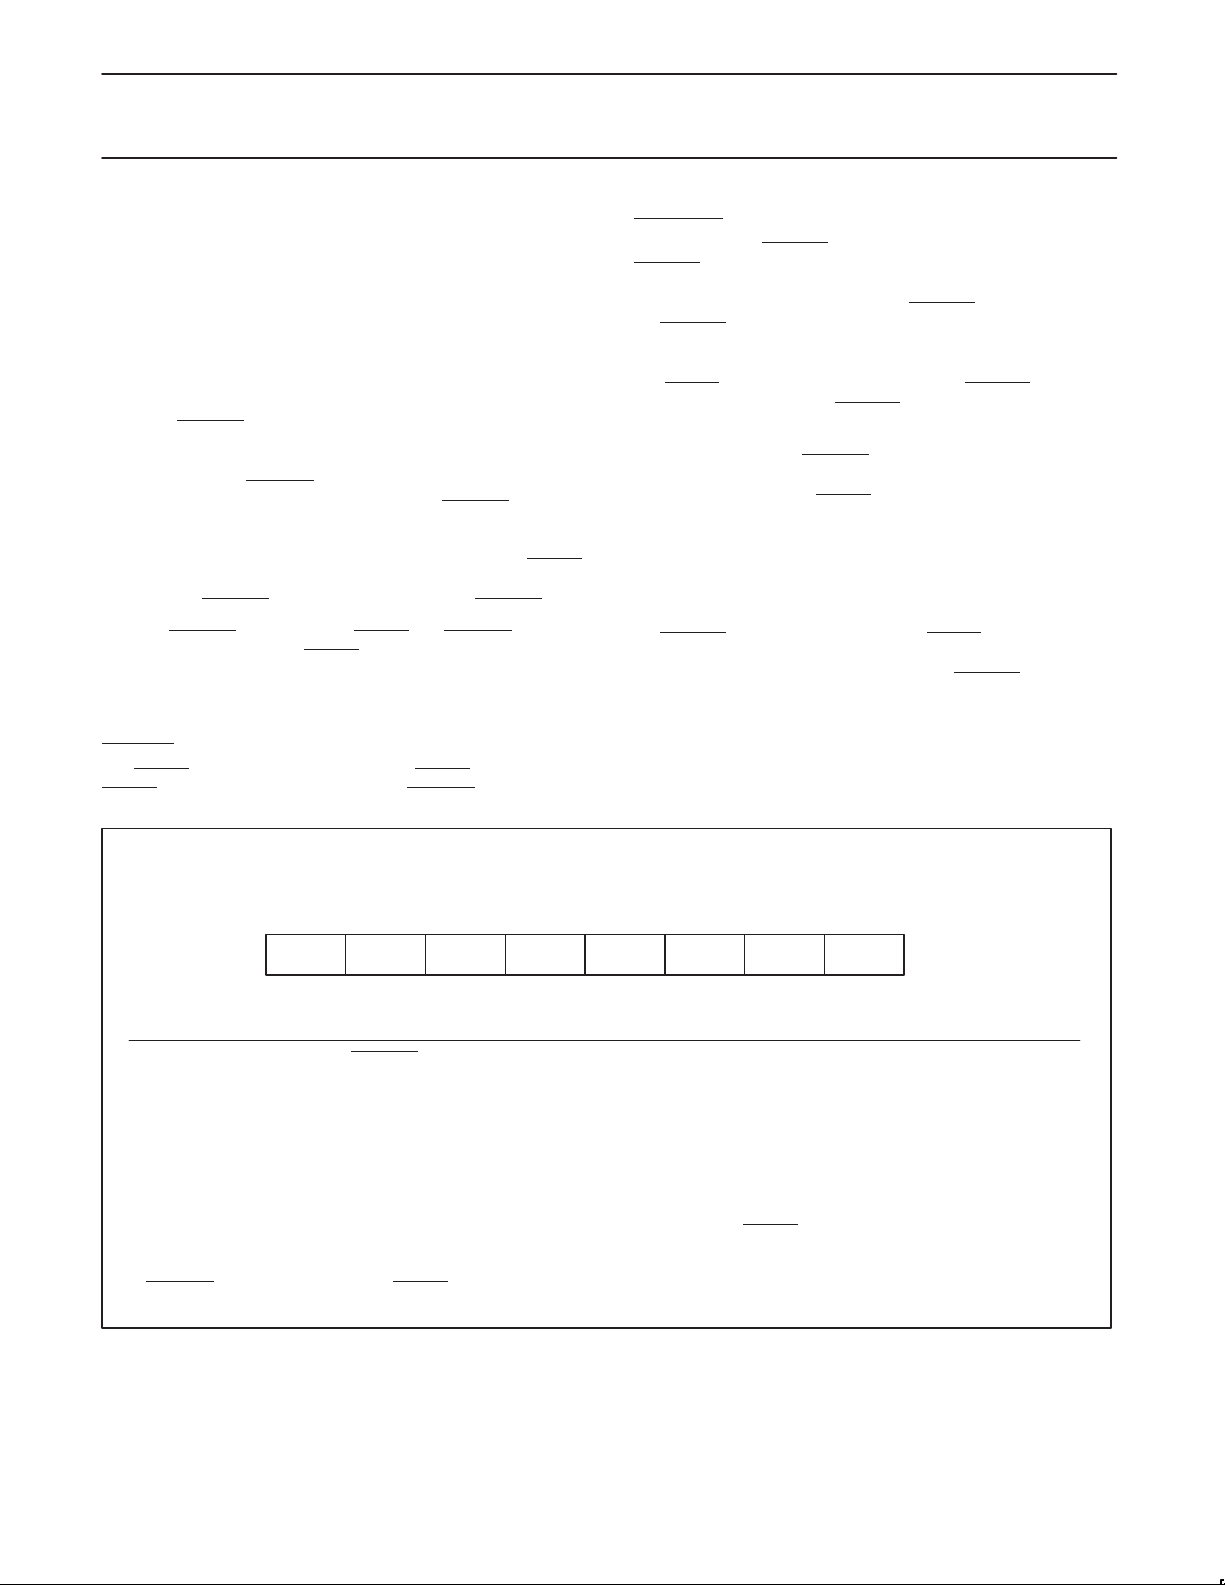
Watchdog reset. Figure 2 shows the fields in the RSTSRC register. If
the ResetOut
will be external resets, and will thus appear as external resets in the
reset source register. RSTSRC[7] enables the ResetOut function; 1 =
Enabled, 0 = Disabled. See
RSTSRC[7] differs in function from most other XA derivatives.
function is tied back into the ResetIn pin, then all resets
XA-H3 User Manual
for details;
RSTSRC
Not Bit Addressable
Reset Value = see below
BIT SYMBOL FUNCTION
RSTSRC.7 ROEN ResetOut
RSTSRC.6 – Reserved for future use. Should not be set to 1 by user programs.
RSTSRC.5 – Reserved for future use. Should not be set to 1 by user programs.
RSTSRC.4 – Reserved for future use. Should not be set to 1 by user programs.
RSTSRC.3 – Reserved for future use. Should not be set to 1 by user programs.
RSTSRC.2 R_WD Indicates that the last reset was caused by a watchdog timer overflow (see WARNING.)
RSTSRC.1 R_CMD Indicates that the last reset was caused by execution of the RESET instruction (see WARNING.)
RSTSRC.0 R_EXT Indicates that the last reset was caused by the external ResetIn
WARNING:
If ResetOut
precedence over internal reset.
Reg Type and Address = SFR 463h
LSBMSB
ROEN — — — — R_WD R_CMD R_EXT
function enable bit – see
function is tied back into ResetIn pin, RSTSRC will always show external reset ONLY, because external reset always takes
Figure 2. RSTSRC Reset Source Register
XA-H3 User Manual
for details
input.
MEMORY CONTROLLER AND I/O BUS INTERFACE
The Memory Controller and bus interface generate bus cycles that are
designed to service SRAMs, Flash, EEPROM, peripheral chips, etc.
The XA-H3 has a highly programmable memory bus interface. Most
SRAMs, Flash, ROMs, and peripheral chips can be connected to this
interface with no external decode logic or interface chips. The bus
interface provides 6 mappable chip select outputs. The bus timing for
each individual memory bank or peripheral can be programmed to
accommodate slow or fast devices, with various bus protocols.
SU01237
1999 Sep 24
18
Page 19
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
Each memory bank and associated chip select is capable of
supporting a 1 MB address space (six chip selects can thus support
6 MB of SRAM and other generic devices.)
XA-H3
Memory Controller
SRAM Controller
Dynamic Bus Sizing
Dynamic Bus Timing
The Memory Interface can be programmed to support both Intel
style and 68000 bus style SRAMs and peripherals.
CS5 (or P3.1, RTS1)
CS4
(or P3.0, RTClk1)
CS3
CS2
CS1
CS0
A19–A0
D15–D0
ClkOut
BHE
BLE
OE
WE
WAIT, SIZE16
SU01238
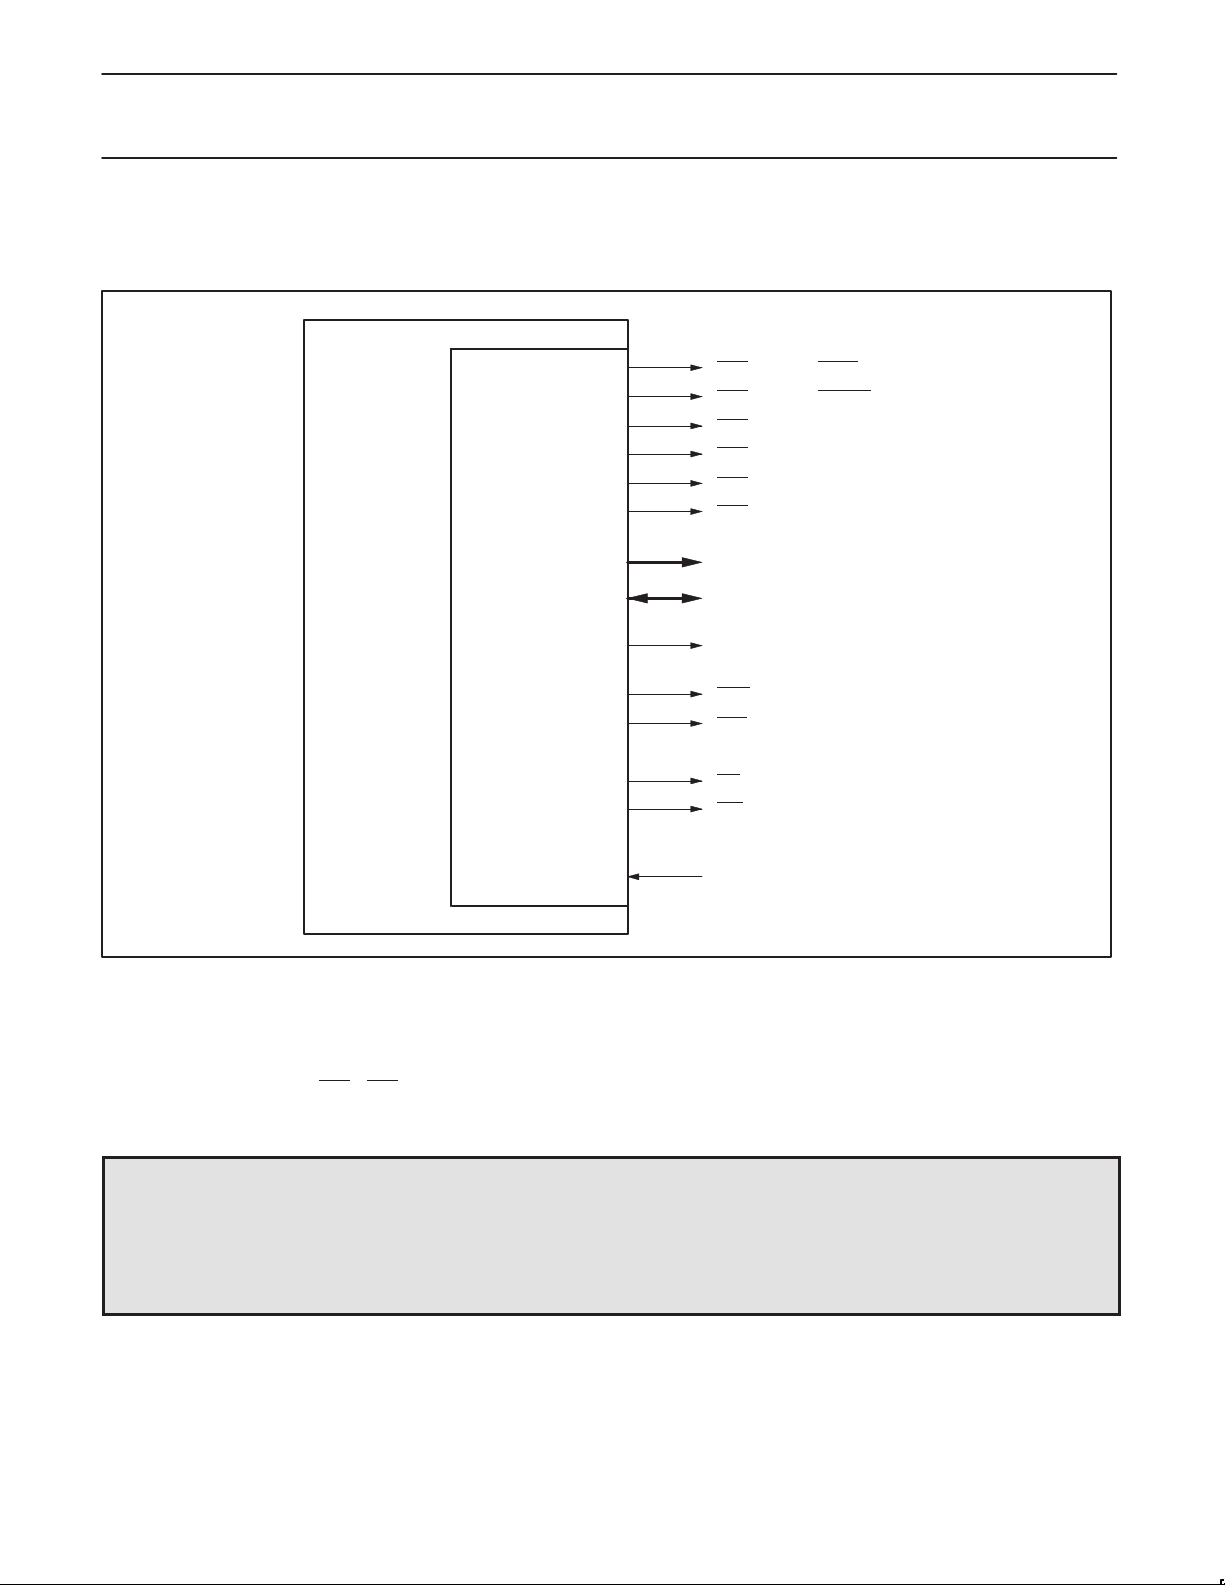
Figure 3. Memory Bus Interface Signal Pins
Bus Interface Pins
For the following discussion, see Figure 3.
Chip Select Pins
There are six chip select pins (CS5 – CS0)mapped to six sets of
bank control registers. The following attributes are individually
programmable for each bank and associated chip select : bank
WARNING: On the external bus, ALL XA-H3 reads are 16-bit Reads. If the CPU instruction only specifies 8-bits, then the CPU uses the appropriate
byte, and discards the extra byte. Thus “8-Bit Reads” and “16-Bit Reads” appear to be identical on the bus. On an 8-bit bus, this will appear
as two consecutive 8-bit reads even though the CPU instruction specified a byte read.
Some 8-bit I/O devices (especially FIFOs) cannot operate correctly with 2 bytes being Read for a 1 Byte Read. The most common (and least
expensive) solution is to operate these 8-bit devices on a 16-bit bus, and access them in software on all odd byte (or all even byte) boundaries.
An added benefit of this technique is that byte reads are faster than on an 8-bit bus, because only 1 word is fetched (a single read) instead of
2 consecutive bytes.
on/off, address range, external device access time, detailed bus
strobe sequence, and bus width.
Clock Output
The CLKOUT pin allows easier external bus interfacing in some
situations. This output reflects the XTALIn clock input to the XA
(referred to internally as CClk or System Clock), but is delayed to
match the external bus outputs and strobes. The default is for
CLKOUT to be output enabled at reset, but it may be turned off
(tri-state disabled) by software via the MICFG MMR.
WARNING: The capacitive loading on this output must not
exceed 40 pf.
1999 Sep 24
19
Page 20
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
CS5
I/O Chip or Memory
CS4
I/O Chip or Memory
CS3
I/O Chip or Memory
CS2
I/O Chip or Memory
XA-H3
CS0
OE
A19–A0
D15–D0
CS1
BLE
BHE
WE
NOTE:
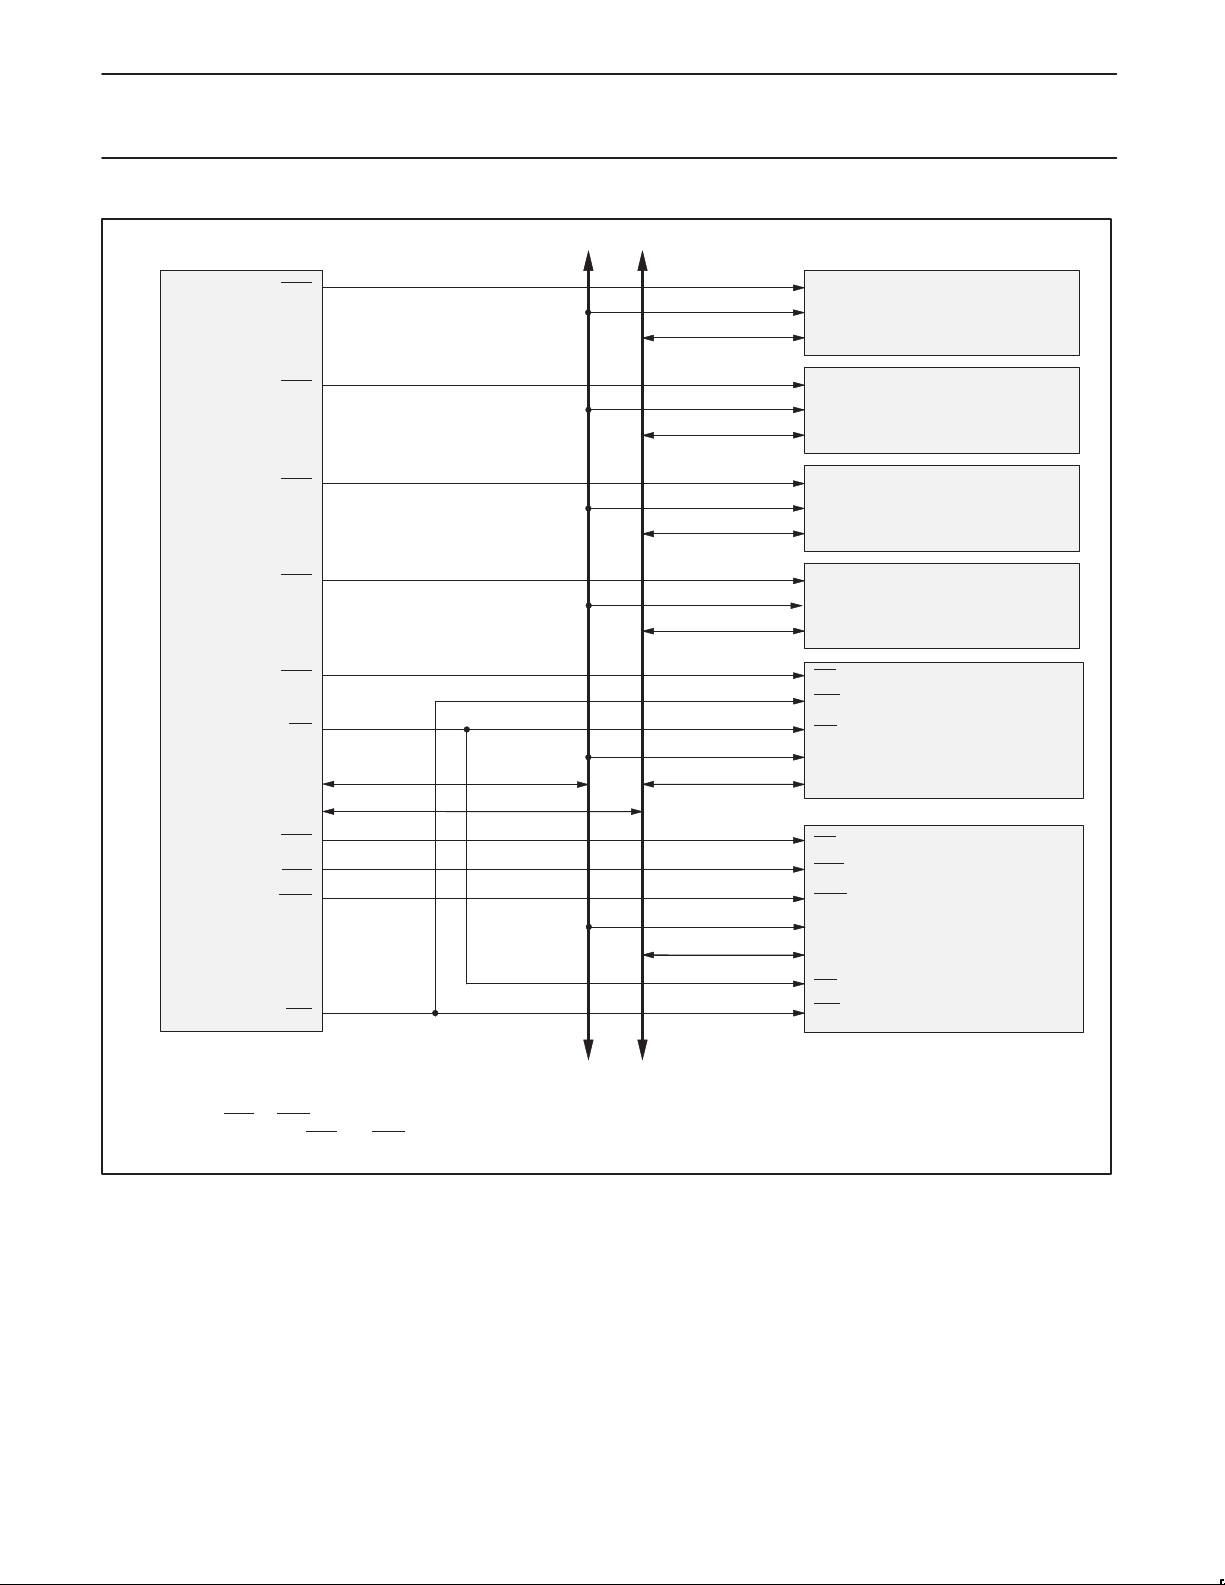
The 16-bit wide RAM does not need the A0 pin from the processor. During byte writes to the RAM, the A0 value will cause
either BLE
Byte Reads, both BLE
or BHE pin to go active from the XA-H3, but not to both. For all Word Writes, Word Reads, Code Fetches, and
and BHE will go active.
Figure 4. Typical System Bus Configuration
A16–A0
D7–D0
A15–A1
D15–D0
CS
WE
OE
A16–A0
D7–D0
CS
BLE
BHE
A15–A1
D15–D0
OE
WE
ROM or Flash
128 k x 8
32 k x 16 SRAM
SU01239
1999 Sep 24
20
Page 21
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
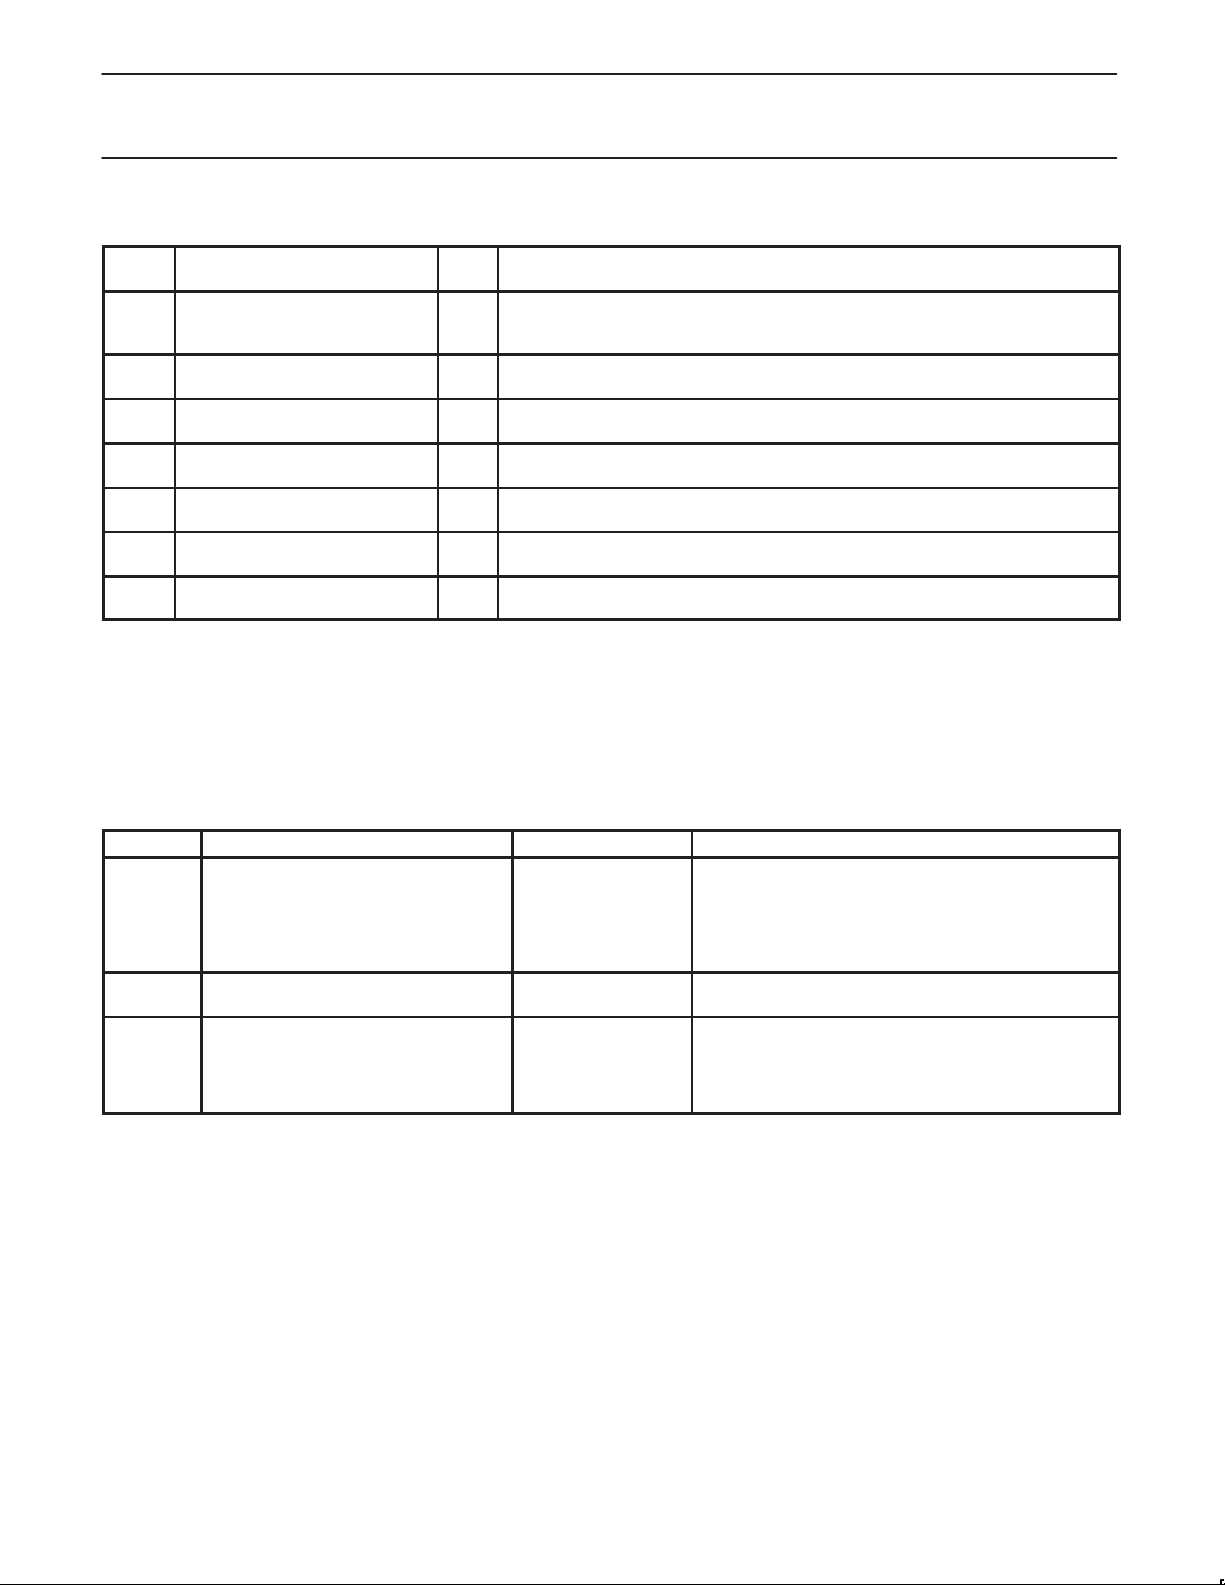
Table 4. Memory interface control registers
Register Name
MRBH “MMR Base Address” High SFR
MRBL “MMR Base Address” Low SFR
MICFG MIF Configuration MMR
MBCL Memory Bank Configuration Lock MMR
BiCFG Bank i Configuration MMR
BiAM Bank i Base Address MMR
BiTMG Bank i Timing MMR
Reg
Type
8 bits
8 bits
8 bits
8 bits
8 bits
8 bits
8 bits
Description
This SFR is used to relocate the MMRs. It contains address bits a23 – a16 of the
base address for the 4 kB Memory Mapped Register space. See the User Manual for
using this SFR to relocate the MMRs.
Contains address bits a15 – a12 of the base address for the 4 kB Memory Mapped
Register space.
Contains the CLKOUT Enable bit.
Contains the bits for locking and unlocking the BiCFG Registers.
Contains the size, type, bus width, and enable bits for Memory Bank i.
Contains the base address bits for Memory Bank i.
Contains the timing control bits for Memory Bank i.
EIGHT CHANNEL DMA CONTROLLER
The XA-H3/H4 has eight DMA channels; one Rx DMA channel
dedicated to each UART Receive (Rx) channel, and one Tx DMA
channel dedicated to each UART Transmit (Tx) channel. All DMA
channels are optimized to support memory efficient circular data
buffers in external memory. All DMA channels can also support
traditional linear data buffers.
Transmit DMA Channel Modes
The four Tx channels have three DMA modes specifically designed
for various applications of the attached UARTs. These modes are
summarized in the following table. Full details for all DMA functions
can be found in the DMA chapter of the
Table 5. Tx DMA modes summary
Mode Byte Count Source Maskable Interrupt Description
Tx
Chaining
Stop on TC Processor loads Byte Count Register Byte count completed
Periodic
Interrupt
Header in memory On stop DMA channel picks up header from memory at end of
(Tx DMA stops)
Loaded by processor into DMA, used by
DMA only to determine the number of
bytes between interrupts. Processor can
calculate the byte count from the DMA
address pointer.
When Byte Counter
reaches zero and is
reloaded by DMA
hardware from the byte
count register.
transmission. If byte count in header is greater than zero,
then DMA transmits the number of bytes specified in the
byte count. If byte count equals 0, then a maskable
interrupt is generated. This process repeats until byte count
in data header is zero. See
Processor loads byte count into DMA. DMA sends that
number of bytes, generates maskable interrupt, and stops.
DMA runs until commanded to stop by processor. CPU
loaded value in Byte Count Register is used to generate
an interrupt for every n bytes. Every time byte counter
rolls over, a new maskable interrupt is generated.
Receive DMA Channel Modes
The Rx DMA channels have two DMA modes specifically designed
for various applications of the attached UARTs. These modes are
summarized in the following table. For full details on implementation
and use, see the
XA-H3 User Manual
XA-H3 User Manual
XA-H3 User Manual
.
.
for details.
1999 Sep 24
21
Page 22
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
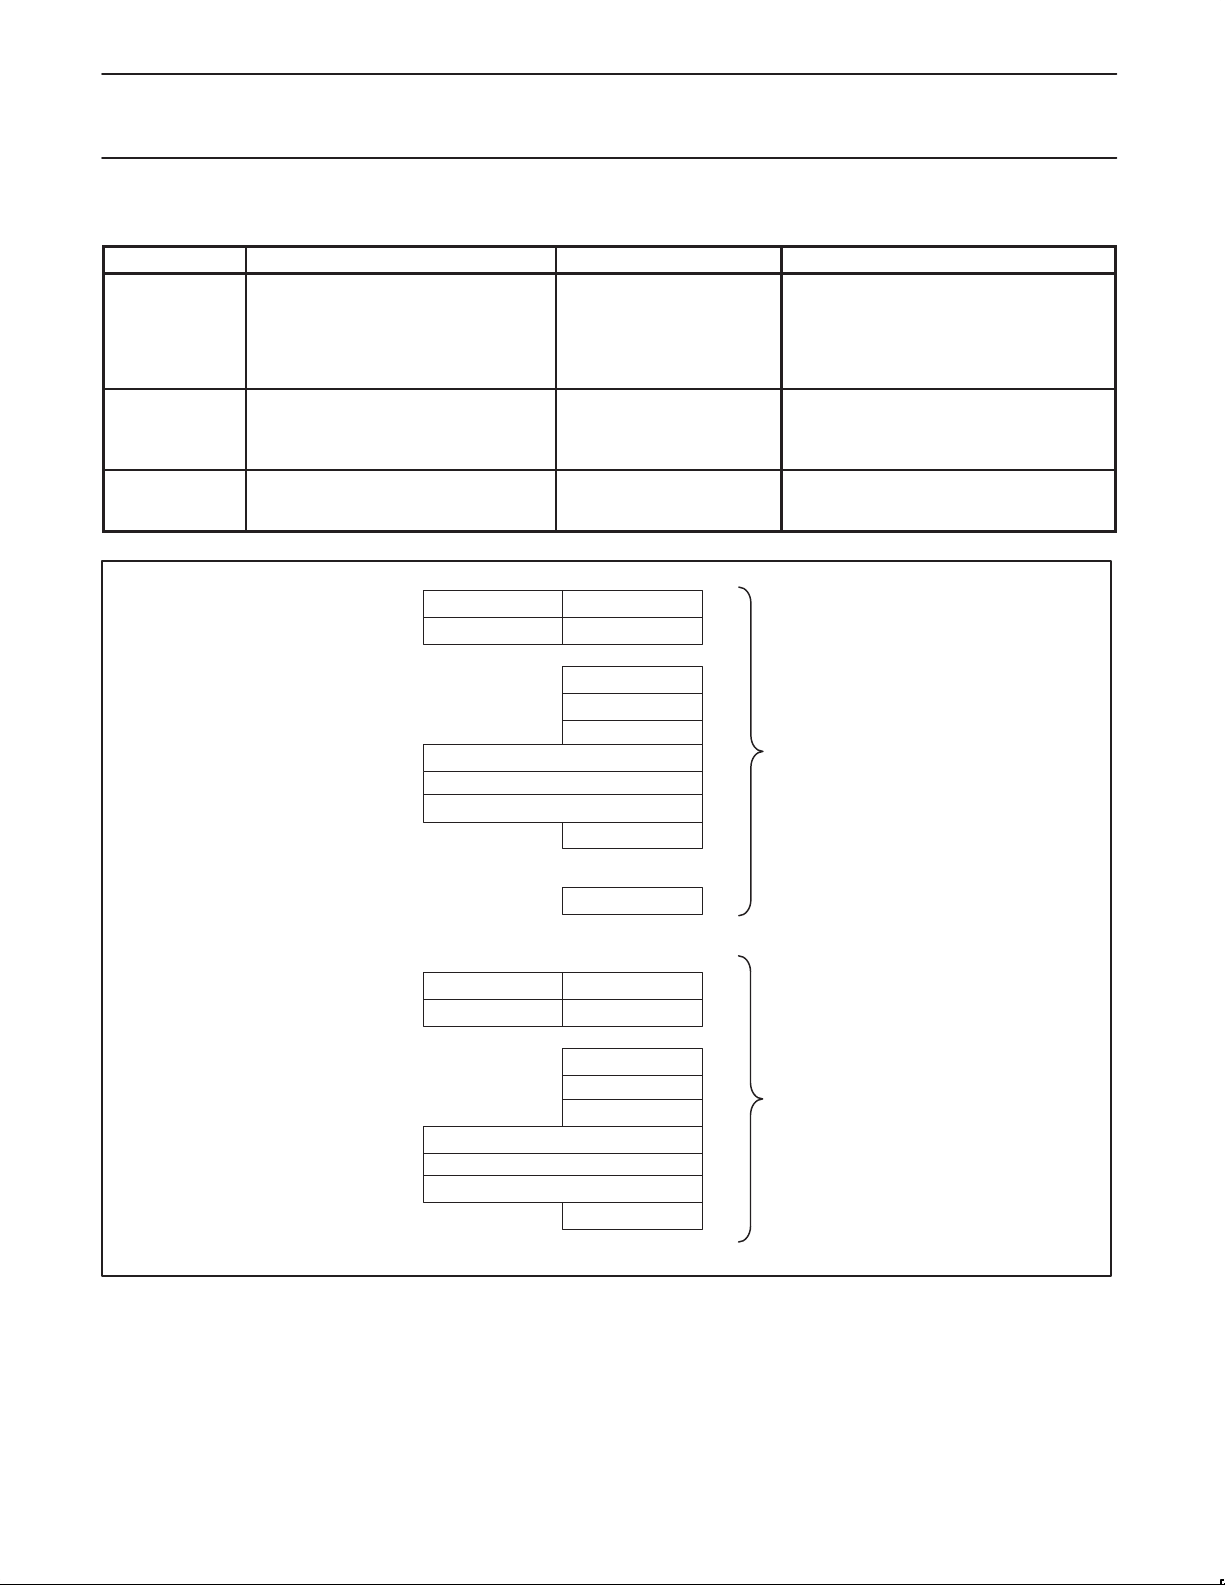
Table 6. Rx DMA modes summary
Mode Byte Count Source Maskable Interrupt Description
Periodic Interrupt Loaded by processor into DMA, used by
Asynchronous
with Character
Time Out
Asynchronous
without interrupt
DMA only to determine the number of
bytes between interrupts. Processor can
calculate the byte count from the DMA
address pointer.
Byte Count can be calculated by software
from the DMA address pointer.
Byte Count can be calculated by software
from the DMA address pointer.
When Byte Counter reaches
zero and is reloaded by DMA
hardware from the byte count
register.
If no character is received
within a specified time out
period, then interrupt.
No interrupt generated Whenever a new character is received, it is
The DMA channel runs until commanded to
stop by the processor. It generates a
maskable interrupt once per n bytes, where n
is the number written once into the byte count
register by the processor, thus an interrupt is
generated once every n received bytes.
Processor specifies time out period between
incoming characters. If no character is
received within that time, a maskable
interrupt is generated.
moved into the memory buffer – no interrupt
is generated.
Data FIFO 3
Data FIFO 1
Buffer Bound
Address Pointer
Byte Count
Data FIFO 3
Data FIFO 1
Buffer Bound
Address Pointer
Byte Count
Data FIFO 2
Data FIFO 0
DMA Control
Buffer Base
FIFO Control
Rx Time Out
Data FIFO 2
Data FIFO 0
DMA Control
Buffer Base
FIFO Control
Segment
Segment
Rx Channel
Tx Channel
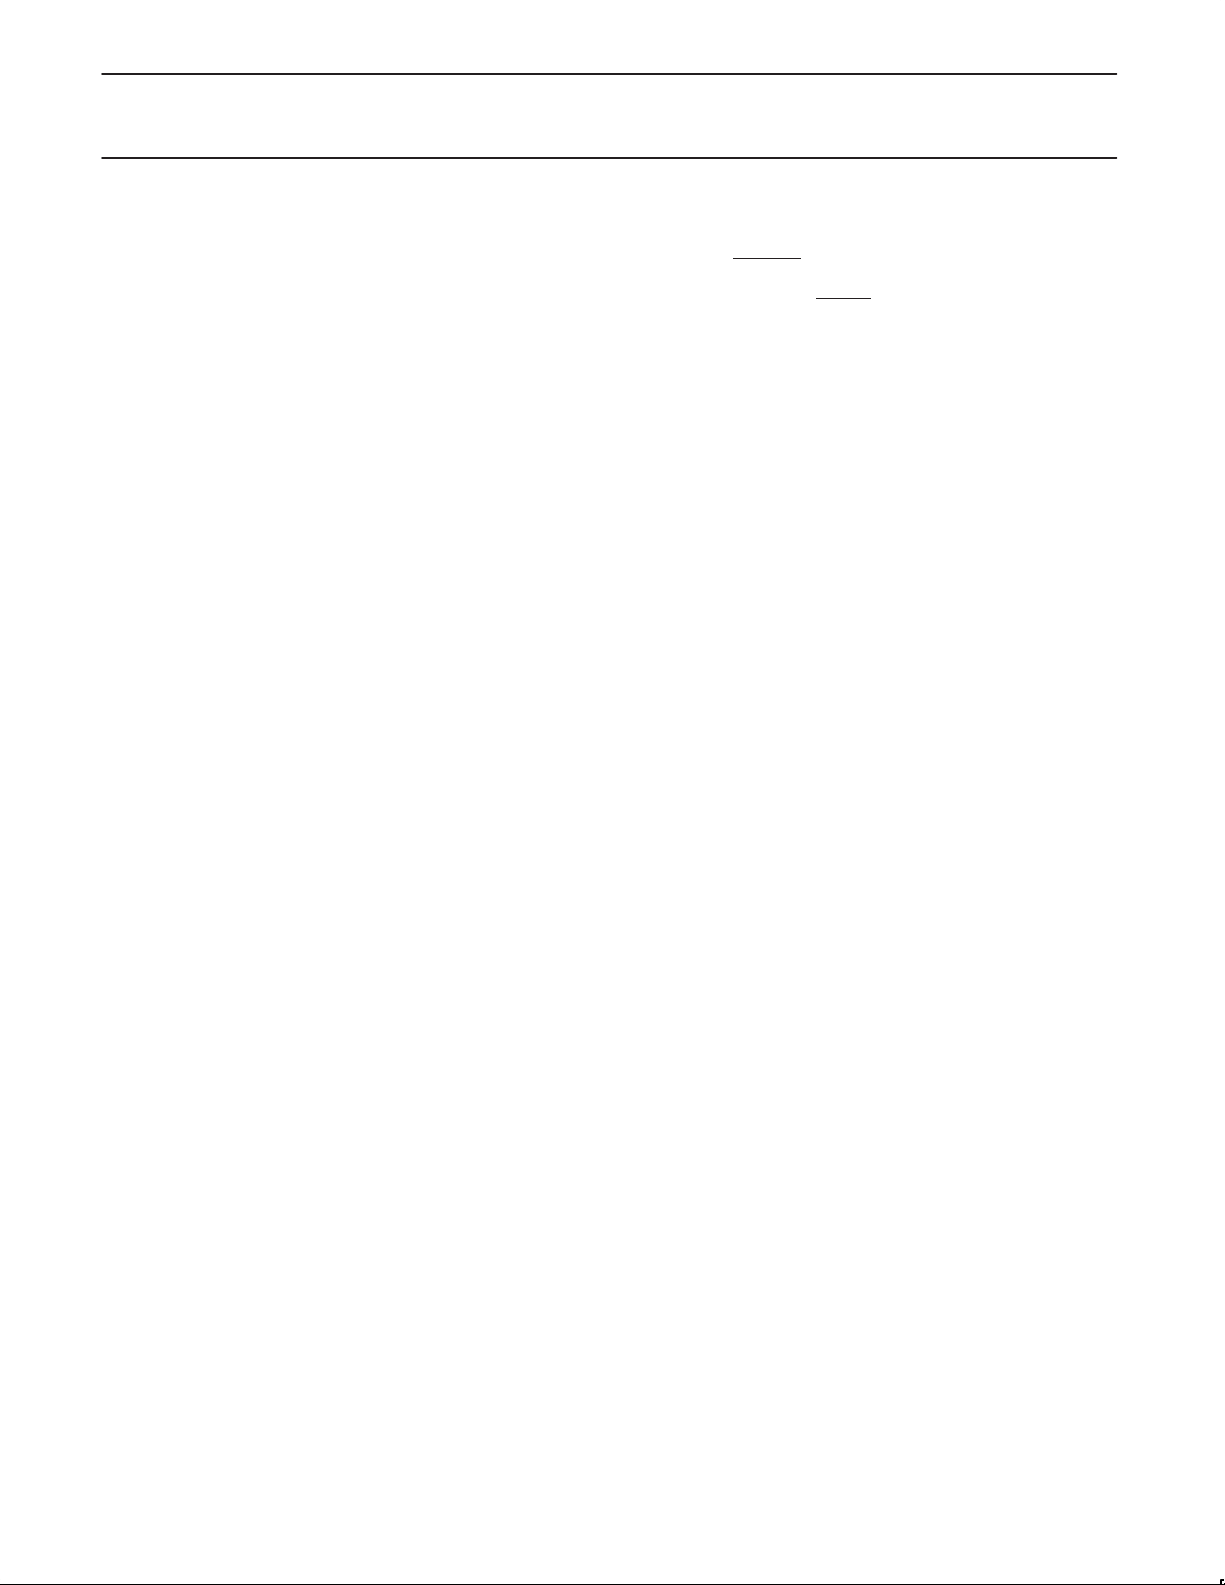
Figure 5. Rx and Tx DMA Registers
DMA Registers
In addition to the 16-bit Global DMA Interrupt Register (which is shared
by all eight DMA channels), each DMA channel has seven control
registers and a four-byte Data FIFO. The four Rx DMA channels have
one additional register, the Rx Character Time Out Register. All DMA
registers can be read and written in Memory Mapped Register (MMR)
space. These registers are summarized below.
1999 Sep 24
SU01240
•Global DMA Interrupt Register (not shown in figure): All DMA
interrupt flags are in this register .
•DMA Control Register: Contains the master mode select and
interrupt enable bits for the channel.
22
Page 23
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
•Segment Register: Holds A23–A16 (the current segment) of the
24-bit data buffer address.
•Buffer Base Register: Holds a pointer (A15–A8) to the lowest byte
in the memory buffer.
•Buffer Bound Register: Points to the first out-of-bounds address
above a circular buffer.
•Address Pointer Register: Points to a single byte or word in the
data buffer in memory. The 24-bit DMA address is formed by
concatenating the contents of the Segment Register [A23–A16]
with the contents of the Address Pointer Register [A15–A0].
•Byte Count Register: Holds the initial number of bytes to be
transferred. In Tx Chaining mode, this register is not used
because the byte count is brought into the byte counter from
buffer headers in memory.
•FIFO Control & Status Register: Holds the queuing order and
full/empty status for the Data FIFO Registers.
•Data FIFO Registers: A four-byte data FIFO buffer internal to the
DMA channel.
•Rx Char Time Out Register (RxCTOR, Rx DMA channels only):
Holds the initial value for an 8-bit character timeout countdown
timer which can generate an interrupt.
Four UARTS
•Asynchronous transfers up to 230.4 kbps
•5, 6, 7, or 8 data bits per character
•1, 1.5, or 2 Stop bits per character
•Even or Odd parity generate and check
•Parity, Rx Overrun, and Framing Error detection
•Break detection
•Programmable Baud Rate Generator
•Auto Echo and Loopback Modes
I/O Port Output Configuration
Port input/output configurations are the same as standard XA ports:
open drain, quasi-bidirectional, push-pull, and off (off means tri-state
Hi-Z, and allows the pin to be used as an input. WARNING: At
power on time, from the time that power coming up is valid, the
P3.2_Timer0_ResetOut
zero nanoseconds up to 258 system clocks. This is true
independently of whether ResetIn
pin may be driven low for any period from
is active or not.
Power Reduction Modes
The XA-H3 supports Idle and Power Down modes of power
reduction. The idle mode leaves most peripherals running in order to
allow them to activate the processor when an interrupt is generated.
The power down mode stops the oscillator in order to absolutely
minimize power. The processor can be made to exit power down
mode via a reset or one of the external interrupt inputs (INT0 or
INT1). This will occur if the interrupt is enabled and its priority is
higher than that defined by IM3 through IM0. In power down mode,
the power supply voltage may be reduced to the RAM keep-alive
voltage VRAM. This retains the RAM, register, and SFR contents at
the point where power down mode was entered. WARNING: V
must be raised to within the operating range before power down
mode is exited.
DD
Interrupts
In the XA architecture, all exceptions, including Reset, are handled in
the same general exception structure. The highest priority exception is
of course Reset, and it is non-maskable. All exceptions are vectored
through the Exception Vector Table in low memory. Coming out of
Reset, these vectors must be stored in non-volatile memory based at
location 000000. Later in the boot sequence, SRAM or other memory
can be mapped into this address space if desired. There is a feature
in the XA-H3 Memory Controller called “Bank Swap” that supports
replacing the ROM vector table and other low memory with RAM. See
the
XA-H3 User Manual
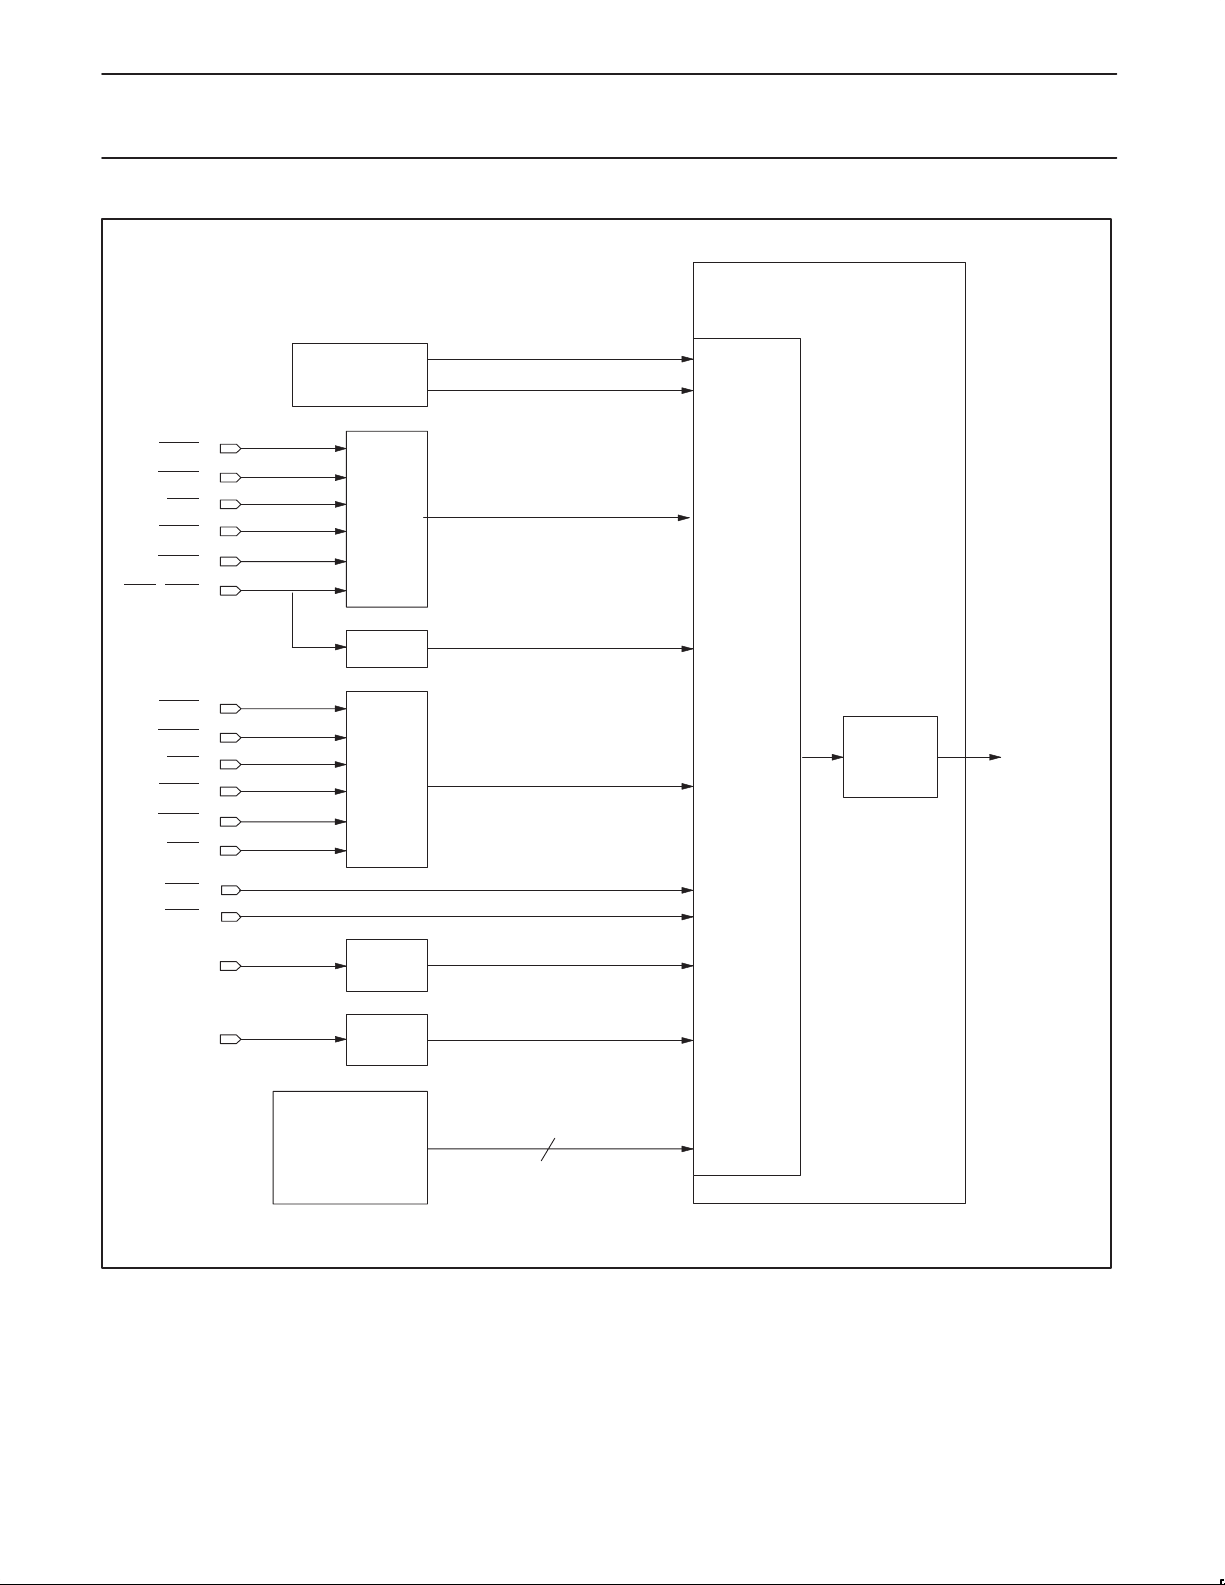
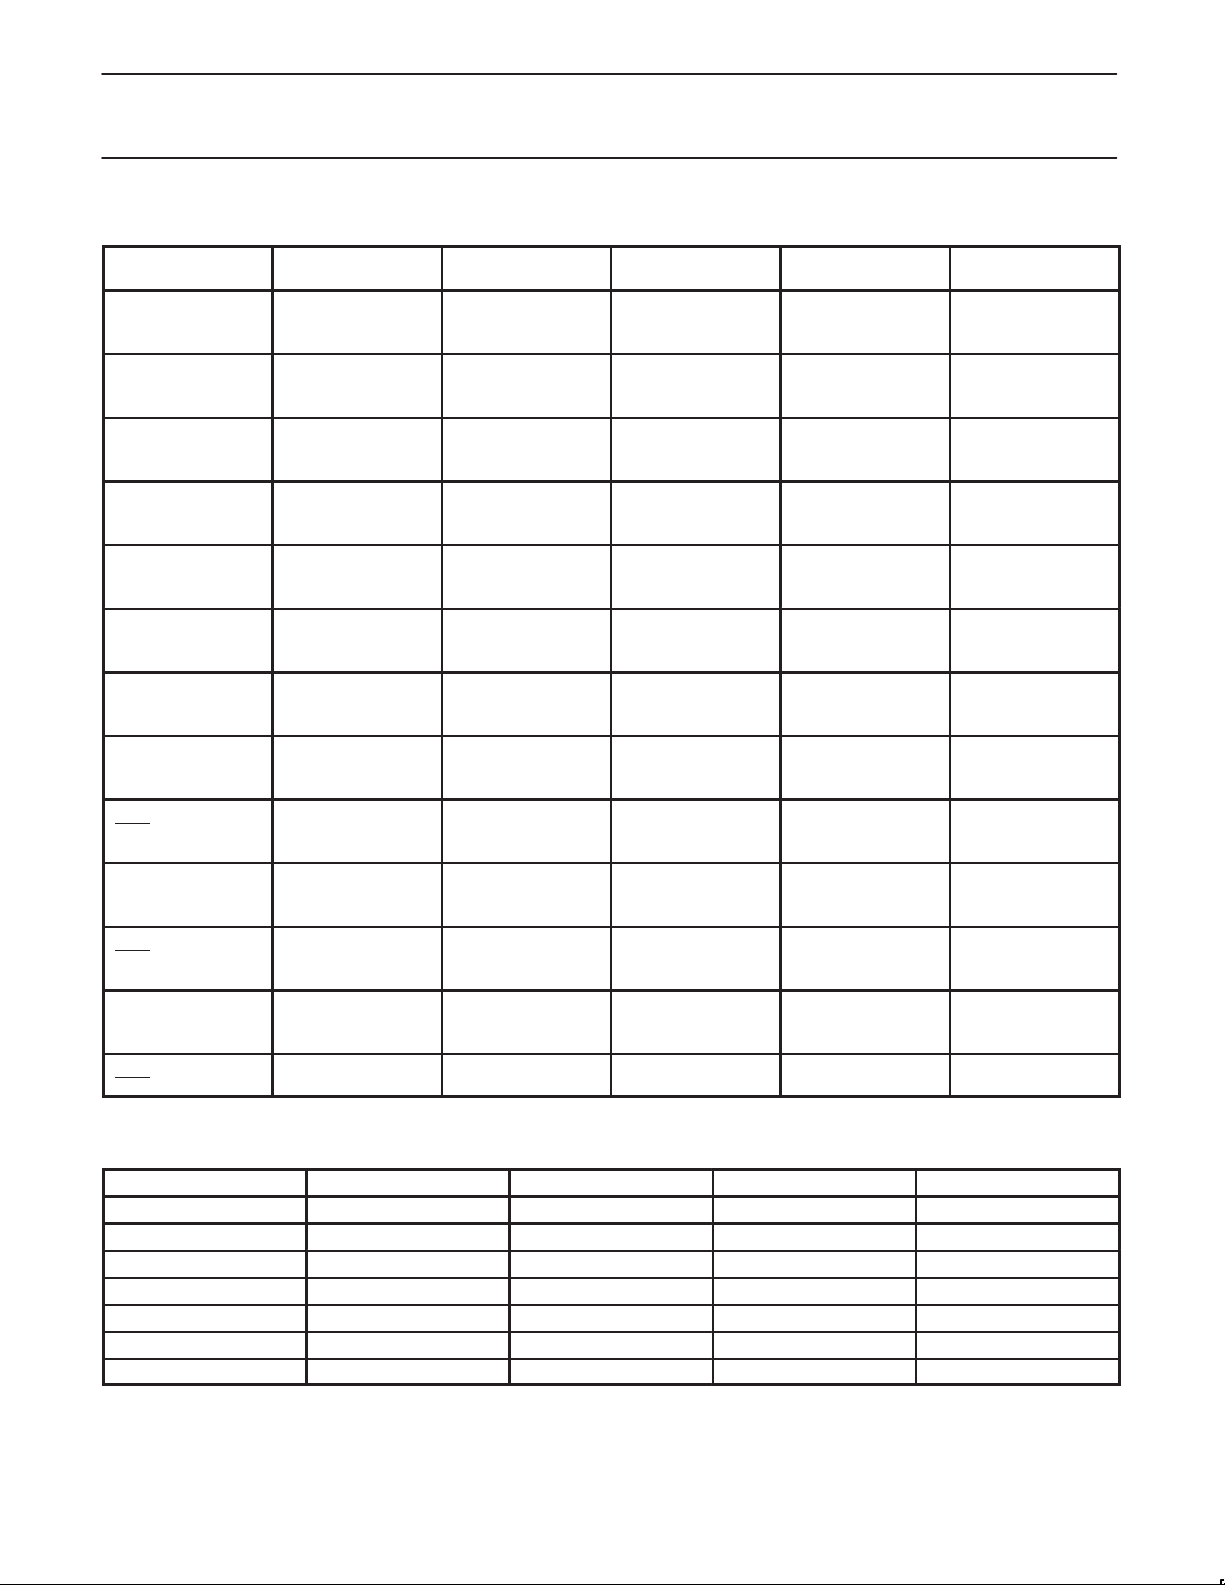
The XA-H3 has a standard XA CPU Interrupt Controller,
implemented with 15 Maskable Event Interrupts. Event Interrupts
are defined as maskable interrupts usually generated by hardware
events. However, in the XA-H3, 4 of the 15 Event Interrupts are
generated by software writing directly to the interrupt flag bit. These
4 interrupts are referred to as High Priority Software Interrupts.
See the IC25 XA Data Handbook for a full explanation of the
exception structure, including event interrupts, of the XA CPU.
Because the High Priority Software Interrupts are specific to the
XA-H3, they are explained in the
for details.
XA-H3 User Manual
.
1999 Sep 24
23
Page 24
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
XA Core
Interrupt Controller
RxD0
CTS0
CD0
RxD1
CTS1
CD1_INT2
RxD2
CTS2
CD2
RxD3
CTS3
CD3
INT0
INT1
DMA
Interrupts
UART0/
UART1
INT2
UART2/
UART3
DMAH
DMAL
Interrupt
Enable/
Disable Bits
Master
Enable
“EA”
Interrupt
To XA CPU
1999 Sep 24
Timer 0
Timer 1
High Priority
Software Ints
HSWR 3–0
4
SU01241
Figure 6. XA-H3 Interrupt Structure Overview
24
Page 25
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
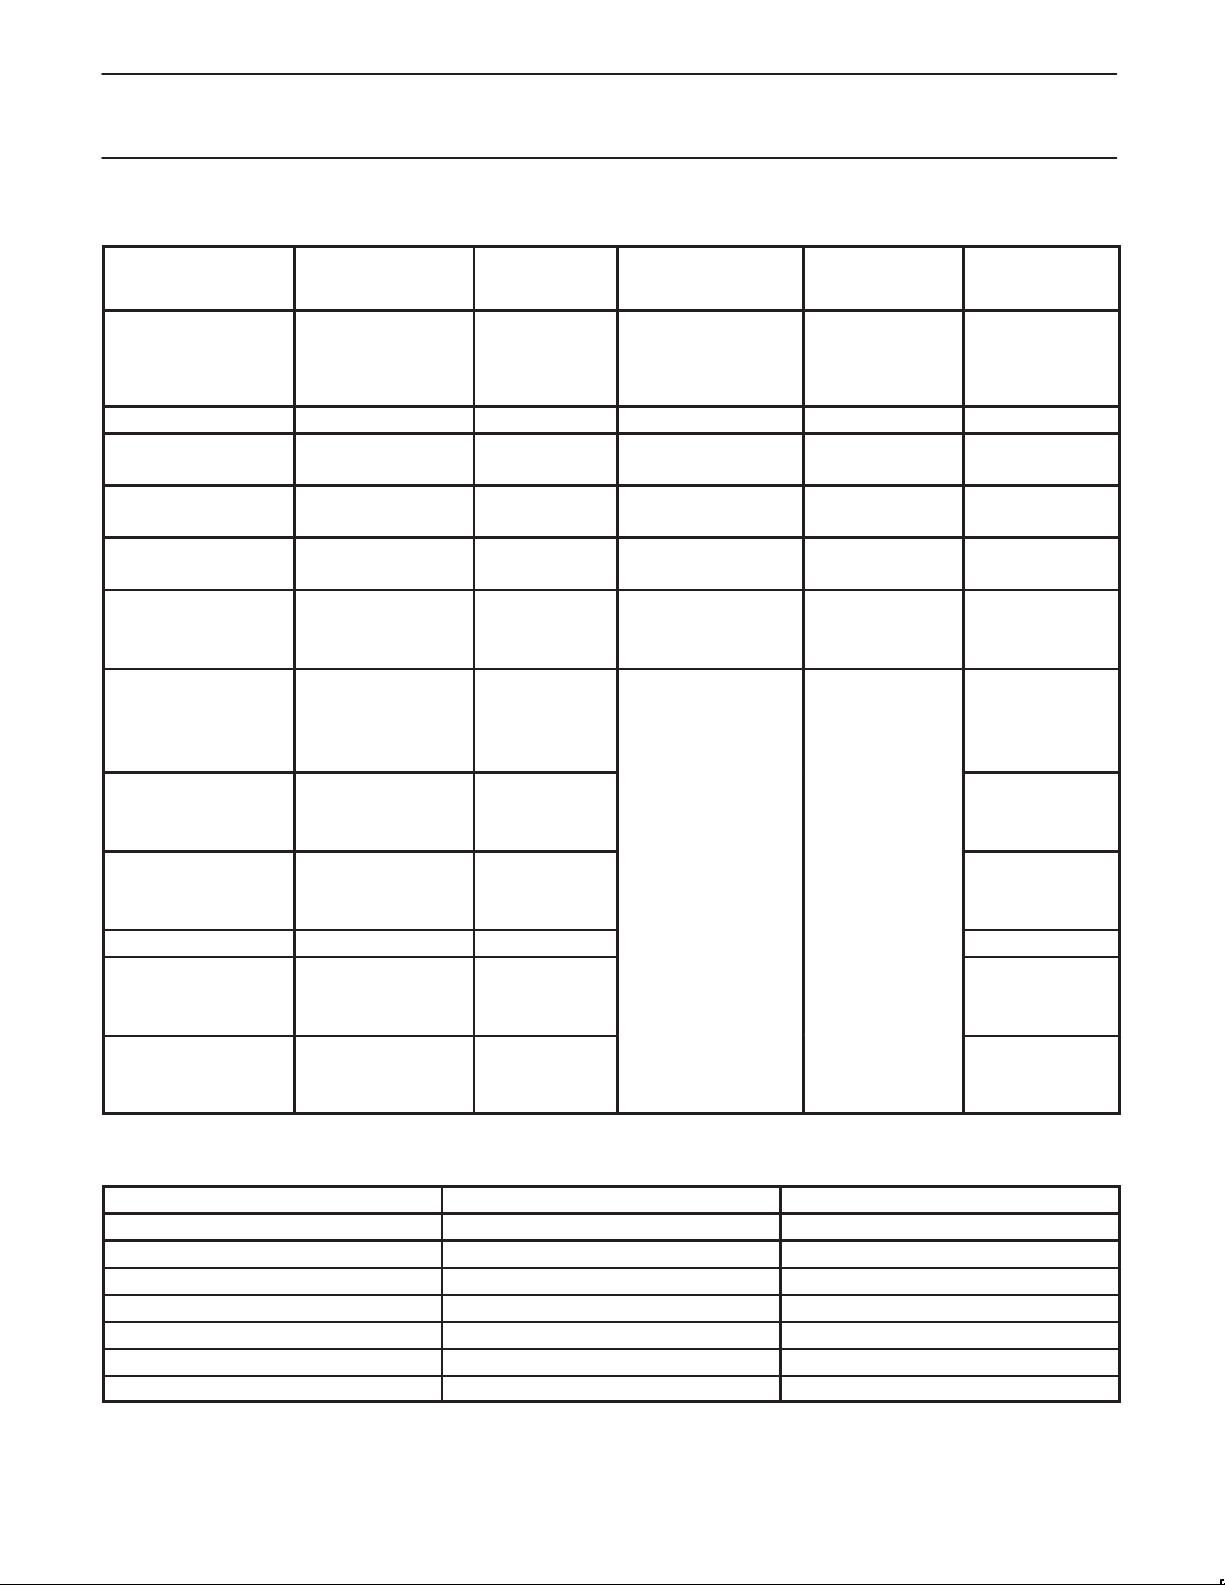
Table 7. UART0 Interrupts (Interrupt structure is the same except for bit locations for all 4 UARTs)
Potential
UART0
Interrupt
Rx Character Available – RR0[0]
CRC/Framing Error – RR1[6]
Rx Overrun – RR1[5]
Parity Error WR1[2]
Tx Buffer Empty See WR1[1] RR0[2]
Break/Abort Break/
Tx Underrun/EOM Tx Underrun/EOM IE
CTS CTS IE
Individual Enable Bit
MMR Hex Offset
802[2]
Abort IE
WR15[7]
81E[7]
WR15[6]
81E[6]
WR15[5]
81E[5]
Source Bit
MMR Hex Offset
820[0]
822[6]
822[5]
RR1[4]
822[4]
820[2]
RR0[7]
820[7]
RR0[6]
820[6]
RR0[5]
820[5]
Group Enable Bit(S)
MMR Hex Offset
WR1[4:3]
802[4:3]
Tx Interrupt Enable
WR1[1]
802[1]
Master External/Status
Interrupt Enable
WR1[0]
802[0]
Group Flag Bit
MMR Hex Offset
Even Channel Rx IP
RR3[5]
826[5]
Even Channel Tx IP
RR3[4]
826[4]
Even Channel
External/Status IP
RR3[3]
826[3]
Master Enable Bit
MMR Hex Offset
UART0/1 Master
Interrupt Enable
WR9[3]
812[3]
DCD DCD IE
WR15[3]
81E[3]
Zero Count Zero Count IE
WR15[1]
81E[1]
RR0[3]
820[3]
RR0[1]
820[1]
EXCEPTION/TRAPS PRECEDENCE
Description Vector Address Arbitration Ranking
Reset (h/w, watchdog, s/w) 0000–0003 0 (High)
Break Point 0004–0007 1
Trace 0008–000B 1
Stack Overflow 000C–000F 1
Divide by 0 0010–0013 1
User RETI 0014–0017 1
TRAP 0–15 (software) 0040–007F 1
1999 Sep 24
25
Page 26
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
EVENT INTERRUPTS
Description Event
Interrupt Source
High Priority
Software Interrupt 3
High Priority
Software Interrupt 2
High Priority
Software Interrupt 1
High Priority
Software Interrupt 0
UART “UART2/3”
Interrupt
UART “UART0/1”
Interrupt
DMA “DMAH”
Interrupt
DMA “DMAL”
Interrupt
External Interrupt 2
(INT2)
Timer 1 TF1
External Interrupt 1
(INT1)
Timer 0 TF0
External Interrupt 0
(INT0)
HSWR3
MMR 2D0[15]
HSWR2
MMR 2D0[14]
HSWR1
MMR 2D0[13]
HSWR0
MMR 2D0[12]
multiple OR from
UART2 & UART3
multiple OR from
UART0 & UART1
multiple OR from
DMA
multiple OR from
DMA
IE2
MMR 2D2[0]
SFR 410[7]
287
IE1
SFR 410[3]
283
SFR 410[5]
285
IE0 SFR 410[1] 0083–0080 EX0 426[0] 330 PX0 4A0[2:0] 2
Flag Bit
Interrupt Vector
Address
00BF–00BC EHSWR3
00BB–00B8 EHSWR2
00B7–00B4 EHSWR1
00B3–00B0 EHSWR0
00A7–00A4 ESC23
00A3–00A0 ESC01
009B–0098 EDMAH
0097–0094 EDMAL
0093–0090 EX2
008F–008C ET1
008B–0088 EX1
0087–0084 ET0
Enable Bit (SFR)
427[7]
33F
427[6]
33E
427[5]
33D
427[4]
33C
427[1]
339
427[0]
338
426[6]
336
426[5]
335
426[4]
334
426[3]
333
426[2]
332
426[1]
331
Priority Register Bit
Field (SFR)
PHSWR3
4A7[6:4]
PHSWR2
4A7[2:0]
PHSWR1
4A6[6:4]
PHSWR0
4A6[2:0]
PSC23
4A4[6:4]
PSC01
4A4[2:0]
PDMAH
4A3[2:0]
PDMAL
4A2[6:4]
PX2
4A2[2:0]
PT1
4A1[6:4]
PX1
4A1[2:0]
PT0
4A0[6:4]
Arb. Rank
17
16
15
14
11
10
8
7
6
5
4
3
SOFTWARE INTERRUPTS
Description Flag Bit Vector Address Enable Bit Interrupt Priority
Software Interrupt 1 SWR1 0100–0103 SWE1 (fixed at 1)
Software Interrupt 2 SWR2 0104–0107 SWE2 (fixed at 2)
Software Interrupt 3 SWR3 0108–010B SWE3 (fixed at 3)
Software Interrupt 4 SWR4 010C–010F SWE4 (fixed at 4)
Software Interrupt 5 SWR5 0110–0113 SWE5 (fixed at 5)
Software Interrupt 6 SWR6 0114–0117 SWE6 (fixed at 6)
Software Interrupt 7 SWR7 0118–01 1B SWE7 (fixed at 7)
1999 Sep 24
26
Page 27
Philips Semiconductors Preliminary specification
Symbol
Parameter
Test Conditions
Unit
8
5
XA-H3CMOS 16-bit highly integrated microcontroller
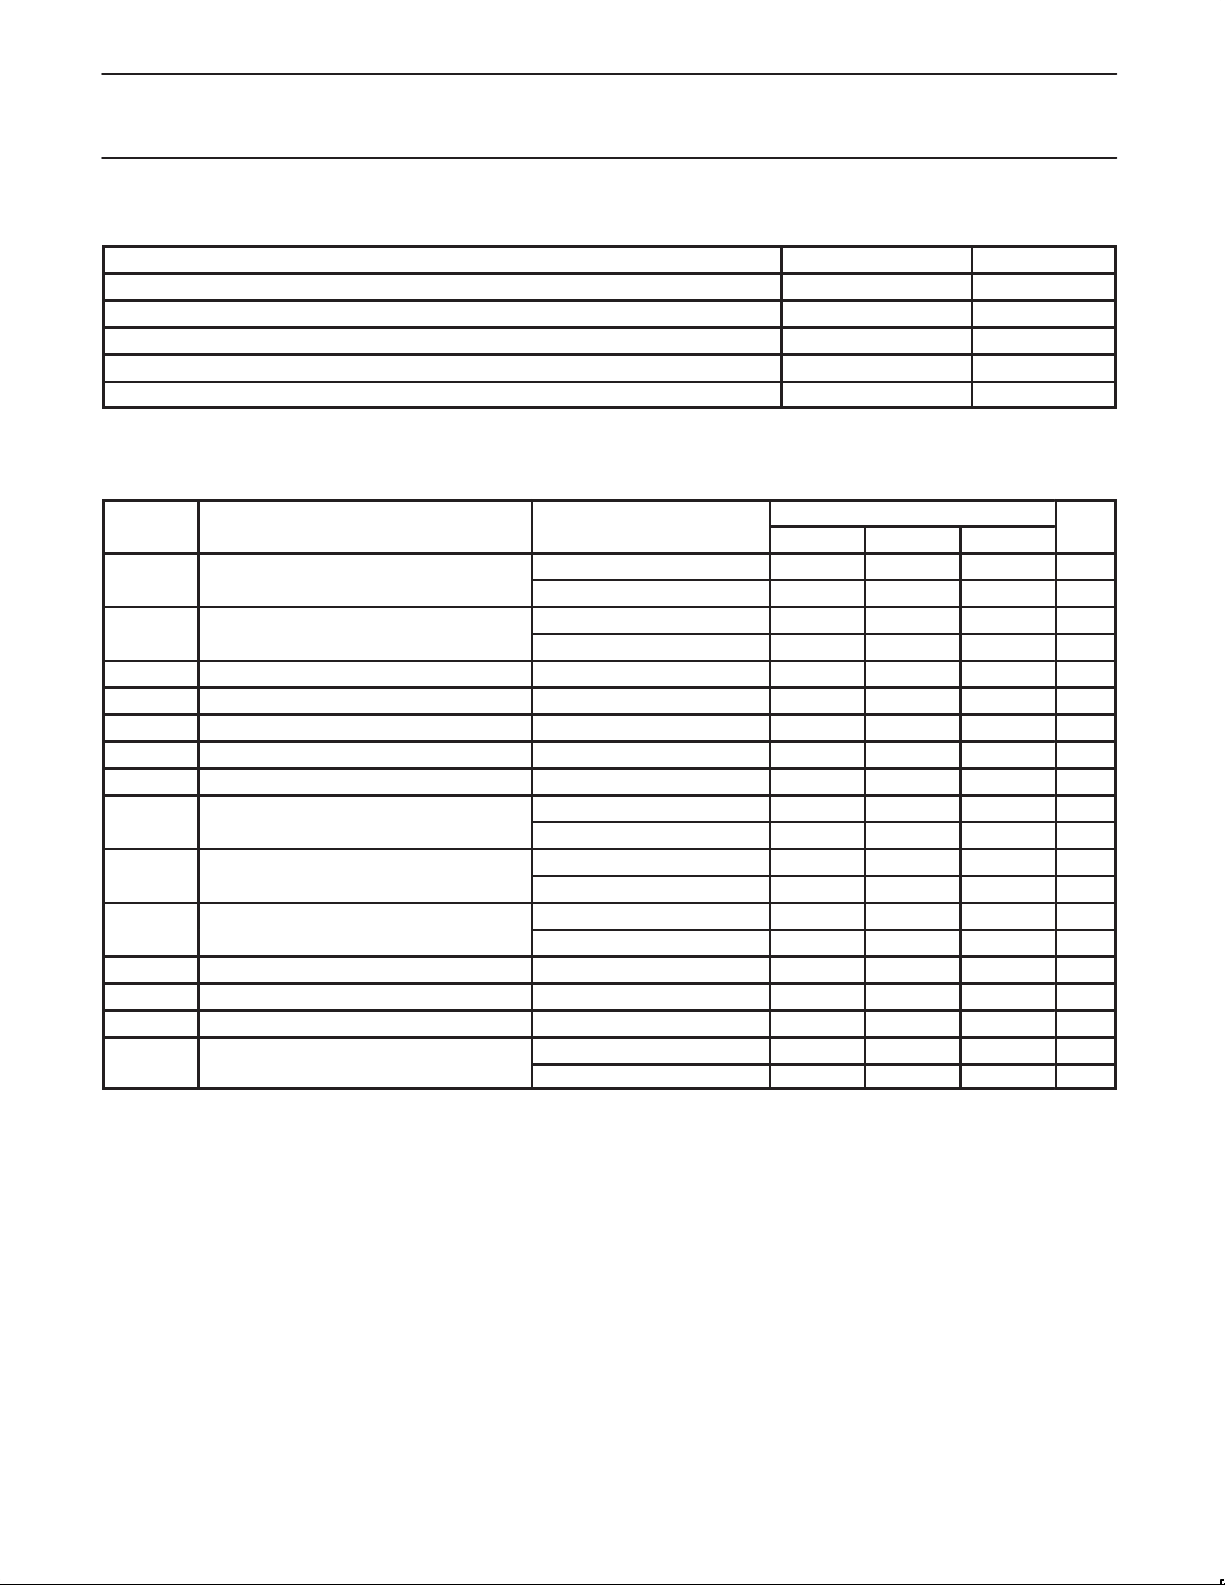
ABSOLUTE MAXIMUM RATINGS
Parameter Rating Unit
Operating temperature under bias –55 to +125 °C
Storage temperature range –65 to +150 °C
Voltage on any other pin to V
SS
Maximum IOL per I/O pin 15 mA
Power dissipation (based on package heat transfer, not device power consumption) 1.5 W
PRELIMINARY DC ELECTRICAL CHARACTERISTICS
VDD = 5.0 V +/– 10% or 3.3 V +/– 10% unless otherwise specified; T
V
V
V
V
I
DD
I
I
PDI
RAM
V
V
V
OH1
OH2
C
I
I
I
ID
IH1
OL
IL
LI
TL
Power supply current, operating
Power supply current, Idle mode
Power supply current, Power Down mode
1
RAM keep-alive voltage 1.5 V
Input low voltage –0.5 0.22 V
IL
Input high voltage, except Xtal1, RST 2.2 V
IH
Input high voltage to Xtal1, RST For both 3.0 & 5.0 V 0.7 V
Output low voltage all ports
Output high voltage, all ports
Output high voltage, all ports
Input/Output pin capacitance 15 pF
IO
Logical 0 input current, all ports
Input leakage current, all ports
7
6
Logical 1 to 0 transition current, all ports
NOTE:
must be raised to within the operating range before power down mode is exited.
1. V
DD
2. Ports in quasi-bidirectional mode with weak pullup.
3. Ports in PUSH-PULL mode, both pullup and pulldown assumed to be the same strength.
4. In all output modes.
5. Port pins source a transition current when used in quasi-bidirectional mode and externally driven from 1 to 0. This current is highest when
V
is approximately 2 V.
IN
6. Measured with port in high impedance mode.
7. Measured with port in quasi-bidirectional mode.
8. Under steady state (non-transient) conditions, IOL must be externally limited as follows:
Maximum I
Maximum I
Maximum total I
If I
exceeds the test condition, VOL may exceed the related specification. Pins are not guaranteed to sink current greater than the listed
OL
test conditions.
per port pin: 15 mA (NOTE: This is +85°C specification for VDD = 5 V)
OL
per 8-bit port: 26 mA
OL
for all outputs: 71 mA
OL
= –40°C to +85°C for industrial, unless otherwise specified.
amb
5.0 V, 30 MHz 64 80 mA
3.3 V, 30 MHz 55 70 mA
5.0 V, 30 MHz 50 70 mA
3.3 V, 30 MHz 44 60 mA
5.0 V, 3.0 V 500 µA
IOL = 3.2 mA, VDD = 4.5 V 0.5 V
IOL = 1.0 mA, VDD = 3.0 V 0.4 V
IOH = –100 µA, VDD = 4.5 V 2.4 V
IOH = –30 µA, VDD = 3.0 V 2.0 V
IOH = 3.2 mA, VDD = 4.5 V 2.4 V
IOH = 1.0 mA, VDD = 3.0 V 2.2 V
VIN = 0.45 V –50 µA
VIN = VIL or V
IH
At VDD = 5.5 V –650 µA
At VDD = 3.6 V –250 µA
–0.5 to VDD+0.5 V v
Limits
Min Typ Max
DD
±10 µA
DD
V
V
1999 Sep 24
27
Page 28
Philips Semiconductors Preliminary specification
Symbol
Figure
Parameter
Unit
XA-H3CMOS 16-bit highly integrated microcontroller
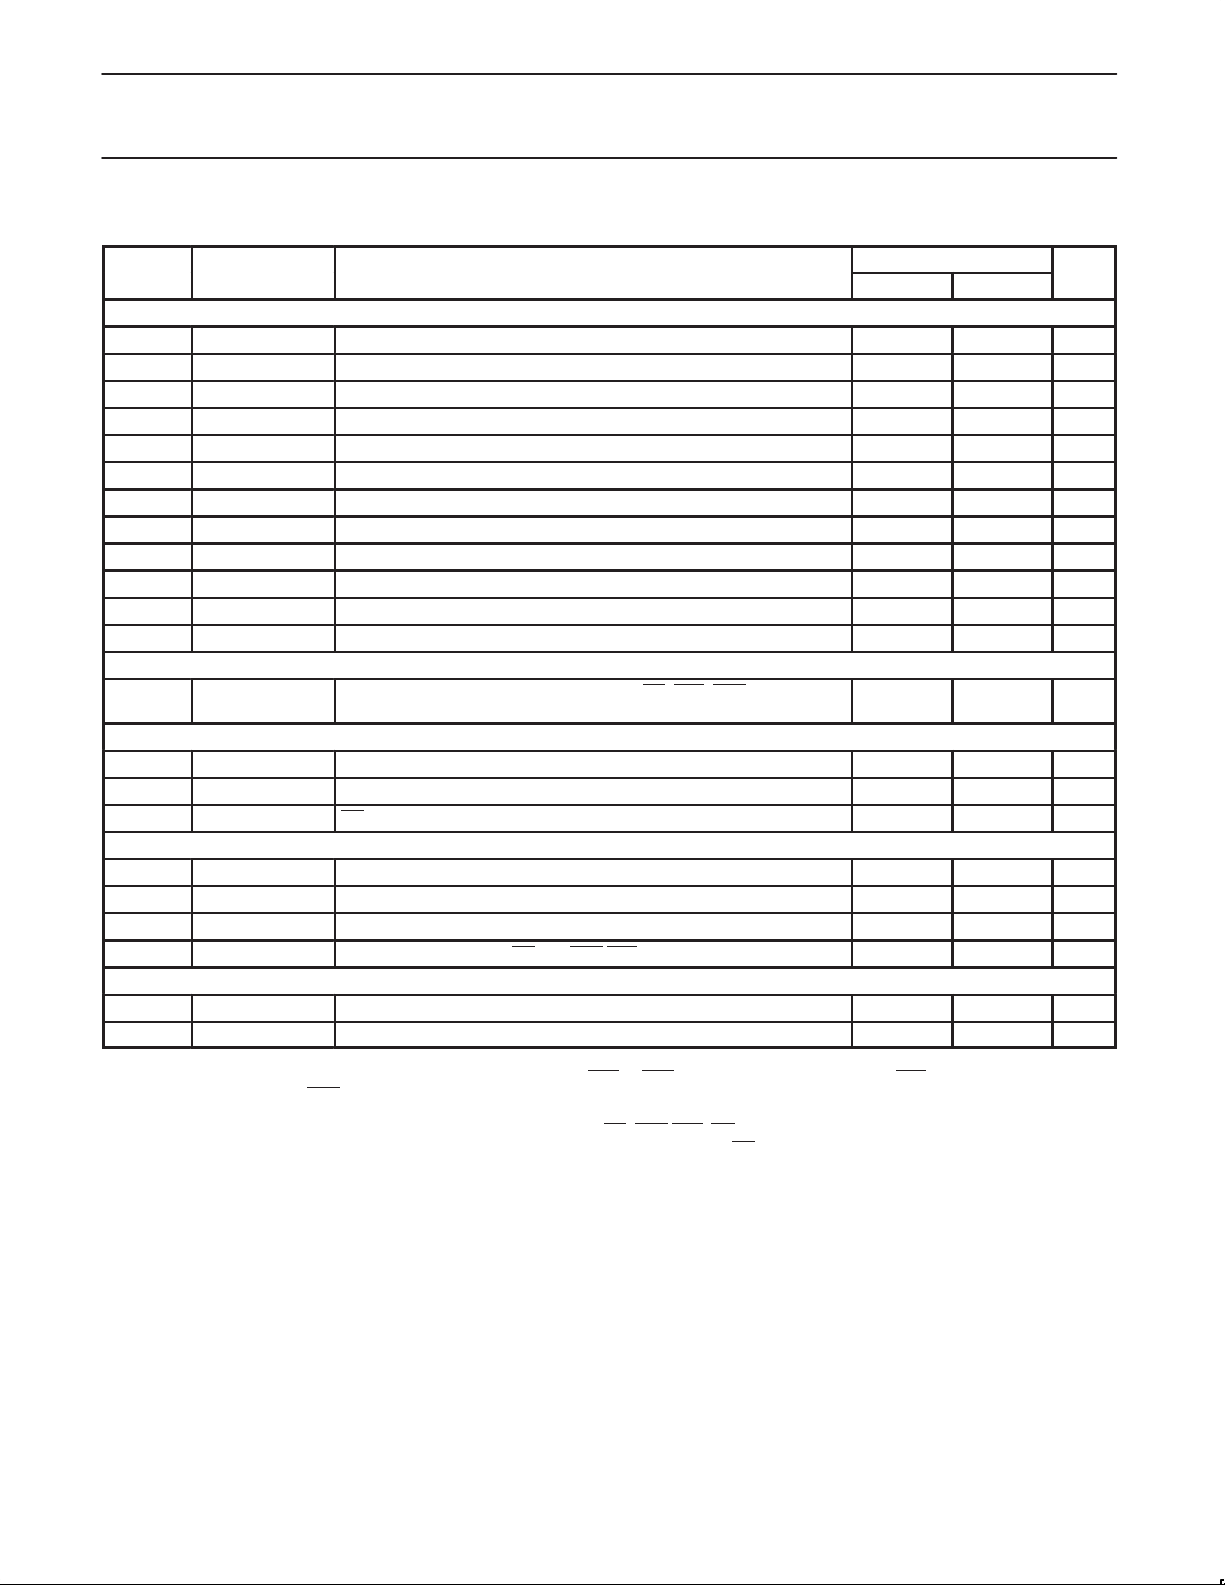
PRELIMINARY AC ELECTRICAL CHARACTERISTICS (5.0 V +/–10%)
Limits
Min Max
All Cycles
F
C
t
C
t
CHCX
t
CLCX
t
CLCH
t
CHCL
t
AVSL
t
CHAH
t
CHAV
t
CHSH
t
CHSL
t
CODH
t
AHDR
t
DIS
t
DIH
t
OHDE
t
CHDV
t
DVSL
t
SHAH
t
SHDH
t
WS
t
WH
13 System Clock Period = 1/FC 33.33 – ns
13 XTALIN High Time tC* 0.5 – ns
13 XTALIN Low Time tC* 0.4 – ns
13 XTALIN Rise Time – 5 ns
13 XTALIN Fall Time – 5 ns
All Address Valid to Strobe low tC – 21 – ns
All Address hold after CLKOUT rising edge
All Delay from CLKOUT rising edge to address valid – 25 ns
All Delay from CLKOUT rising edge to Strobe High
All Delay from CLKOUT rising edge to Strobe Low
14 ClkOut Duty Cycle High (into 40 pF max.) t
10 Address hold (A19 – A1 only, not A0) after CS, BLE, BHE rise at end
7, 8, 10, 11 Data In Valid setup to ClkOut rising edge 25 – ns
7, 8, 10, 11 Data In Valid hold after ClkOut rising edge
10 OE high to XA Data Bus Driver Enable tC – 14 – ns
9 Clock High to Data Valid – 25 ns
12 Data Valid prior to Strobe Low tC – 23 – ns
9, 12 Minimum Address Hold Time after strobe goes inactive tC – 25 – ns
9, 12 Data hold after strobes (CS and BHE/BLE) high tC – 25 – ns
15 WAIT setup (stable high or low) to CLKOUT rising edge 20 – ns
15 WAIT hold (stable high or low) after CLKOUT rising edge 0 – ns
NOTE:
1. On a 16-bit bus, if only one byte is being written, then only one of BLE
even address) accesses. BHE
2. The bus timing is designed to make meeting hold time very straightforward without glue logic. On all reads and fetches, in order to meet hold
time, the slave should hold data valid on the bus until the earliest of CS
3. To avoid 3-State fights during read cycles and fetch cycles, do not drive data bus until OE
4. WARNING: ClkOut is specified at 40 pF max. More than 40 pf on ClkOut may significantly degrade the ClkOut waveform. Load capacitance
for all outputs (except ClkOut) = 80 pF.
5. Not all combinations of bus timing configuration values result in valid bus cycles. Please refer to the
6. When code is being fetched on the external bus, a burst mode fetch is used. This burst can be from 2 to 16 bytes long. On a 16-bit bus,
A3 – A1 are incremented for each new word of the burst. On an 8-bit bus, A3 – A0 are incremented for each new byte of the burst code fetch.
7. The MIN value for this parameter is guaranteed by design and is not tested in production to the specified limit. In those cases where a
maximum value is specified in the table for this parameter, it is tested.
System Clock Frequency 0 30 MHz
7
7
7
1 – ns
1 21 ns
1 19 ns
CHCX
–7 t
CHCX
+3 ns
Data Read Only
tC – 12 – ns
of Data Read Cycle (not code fetch)
Data Read and Instruction Fetch Cycles
2
0 – ns
Write Cycles
Wait Input
or BHE will go active. On an 8-bit bus, BLE goes active for all (odd or
will not go active during any accesses on an 8 bit bus.
, BHE/BLE, OE, goes high (inactive), or until the address changes.
goes active
XA-H3 User Manual
for details.
1999 Sep 24
28
Page 29
Philips Semiconductors Preliminary specification
Symbol
Figure
Parameter
Unit
XA-H3CMOS 16-bit highly integrated microcontroller
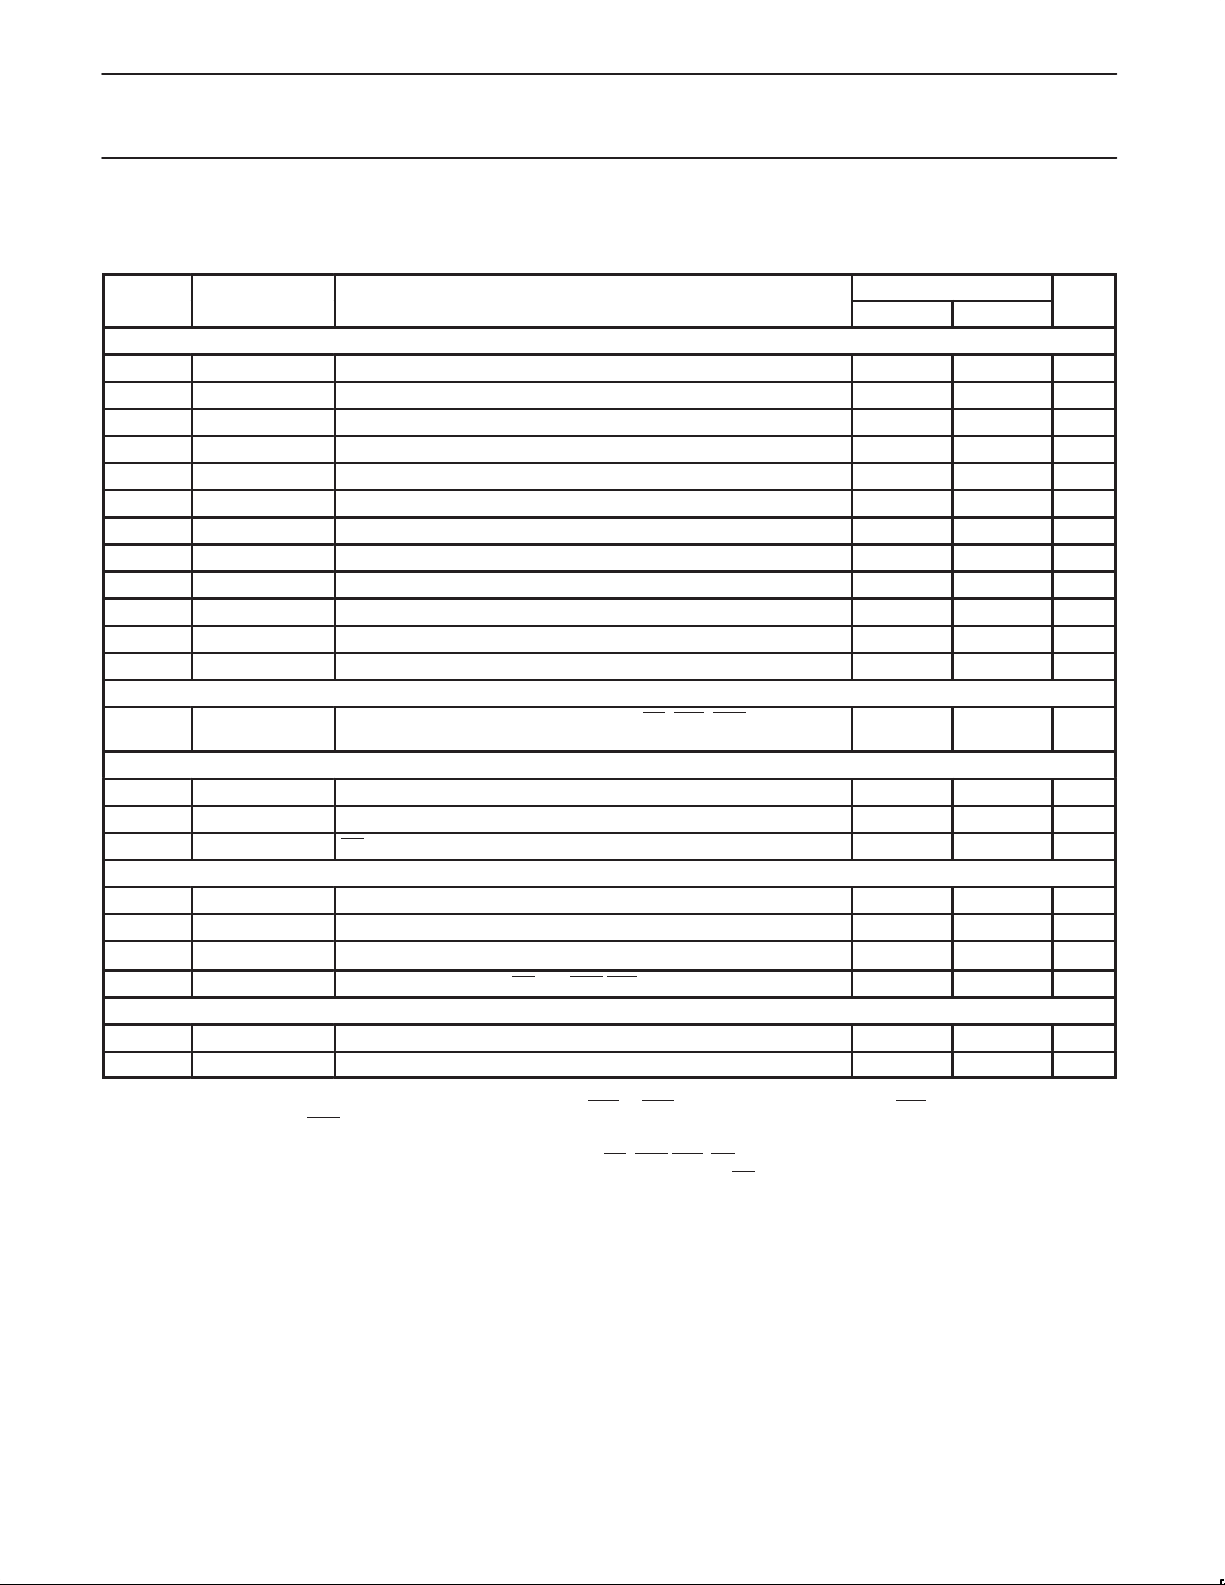
AC ELECTRICAL CHARACTERISTICS (3.3 V +/–10%)
Vdd = 3.3 V +/– 10%; T
F
C
t
C
t
CHCX
t
CLCX
t
CLCH
t
CHCL
t
AVSL
t
CHAH
t
CHAV
t
CHSH
t
CHSL
t
CODH
t
AHDR
t
DIS
t
DIH
t
OHDE
t
CHDV
t
DVSL
t
SHAH
t
SHDH
t
WS
t
WH
7, 8, 10, 11 Data In Valid setup to ClkOut rising edge 32 – ns
7, 8, 10, 11 Data In Valid hold after ClkOut rising edge
NOTE:
1. On a 16-bit bus, if only one byte is being written, then only one of BLE
even address) accesses. BHE
2. The bus timing is designed to make meeting hold time very straightforward without glue logic. On all reads and fetches, in order to meet hold
time, the slave should hold data valid on the bus until the earliest of CS
3. To avoid 3-State fights during read cycles and fetch cycles, do not drive data bus until OE
4. WARNING: ClkOut is specified at 40 pF max. More than 40 pf on ClkOut may significantly degrade the ClkOut waveform. Load capacitance
for all outputs (except ClkOut) = 80 pF.
5. Not all combinations of bus timing configuration values result in valid bus cycles. Please refer to the
6. When code is being fetched on the external bus, a burst mode fetch is used. This burst can be from 2 to 16 bytes long. On a 16-bit bus,
A3 – A1 are incremented for each new word of the burst. On an 8-bit bus, A3 – A0 are incremented for each new byte of the burst code fetch.
7. The MIN value for this parameter is guaranteed by design and is not tested in production to the specified limit. In those cases where a
maximum value is specified in the table for this parameter, it is tested.
= –40°C to +85°C ( industrial )
amb
Limits
Min Max
All Cycles
System Clock (internally called CClk) Frequency 0 30 MHz
13 System Clock Period = 1/FC 33.33 – ns
13 XTALIN High Time tC* 0.5 – ns
13 XTALIN Low Time tC* 0.4 – ns
13 XTALIN Rise Time – 5 ns
13 XTALIN Fall Time – 5 ns
All Address Valid to Strobe low tC – 21 – ns
All Address hold after CLKOUT rising edge
7
1 – ns
All Delay from CLKOUT rising edge to address valid – 30 ns
All Delay from CLKOUT rising edge to Strobe High
All Delay from CLKOUT rising edge to Strobe Low
14 ClkOut Duty Cycle High (into 40 pF max.) t
7
7
1 28 ns
1 25 ns
CHCX
–7 t
CHCX
+3 ns
Data Read Only
10 Address hold (A19 – A1 only, not A0) after CS, BLE, BHE rise at end
tC – 12 – ns
of Data Read Cycle (not code fetch)
Data Read and Instruction Fetch Cycles
2
0 – ns
10 OE high to XA Data Bus Driver Enable tC – 19 – ns
Write Cycles
9 Clock High to Data Valid – 30 ns
12 Data Valid prior to Strobe Low tC – 23 – ns
9, 12 Minimum Address Hold Time after strobe goes inactive
tC – 25
– ns
9, 12 Data hold after strobes (CS and BHE/BLE) high tC – 25 – ns
Wait Input
15 WAIT setup (stable high or low)prior to CLKOUT rising edge 25 – ns
15 WAIT hold (stable high or low) after CLKOUT rising edge 0 – ns
or BHE will go active. On an 8-bit bus, BLE goes active for all (odd or
will not go active during any accesses on an 8-bit bus.
, BHE/BLE, OE, goes high (inactive), or until the address changes.
goes active
XA-H3 User Manual
for details.
1999 Sep 24
29
Page 30
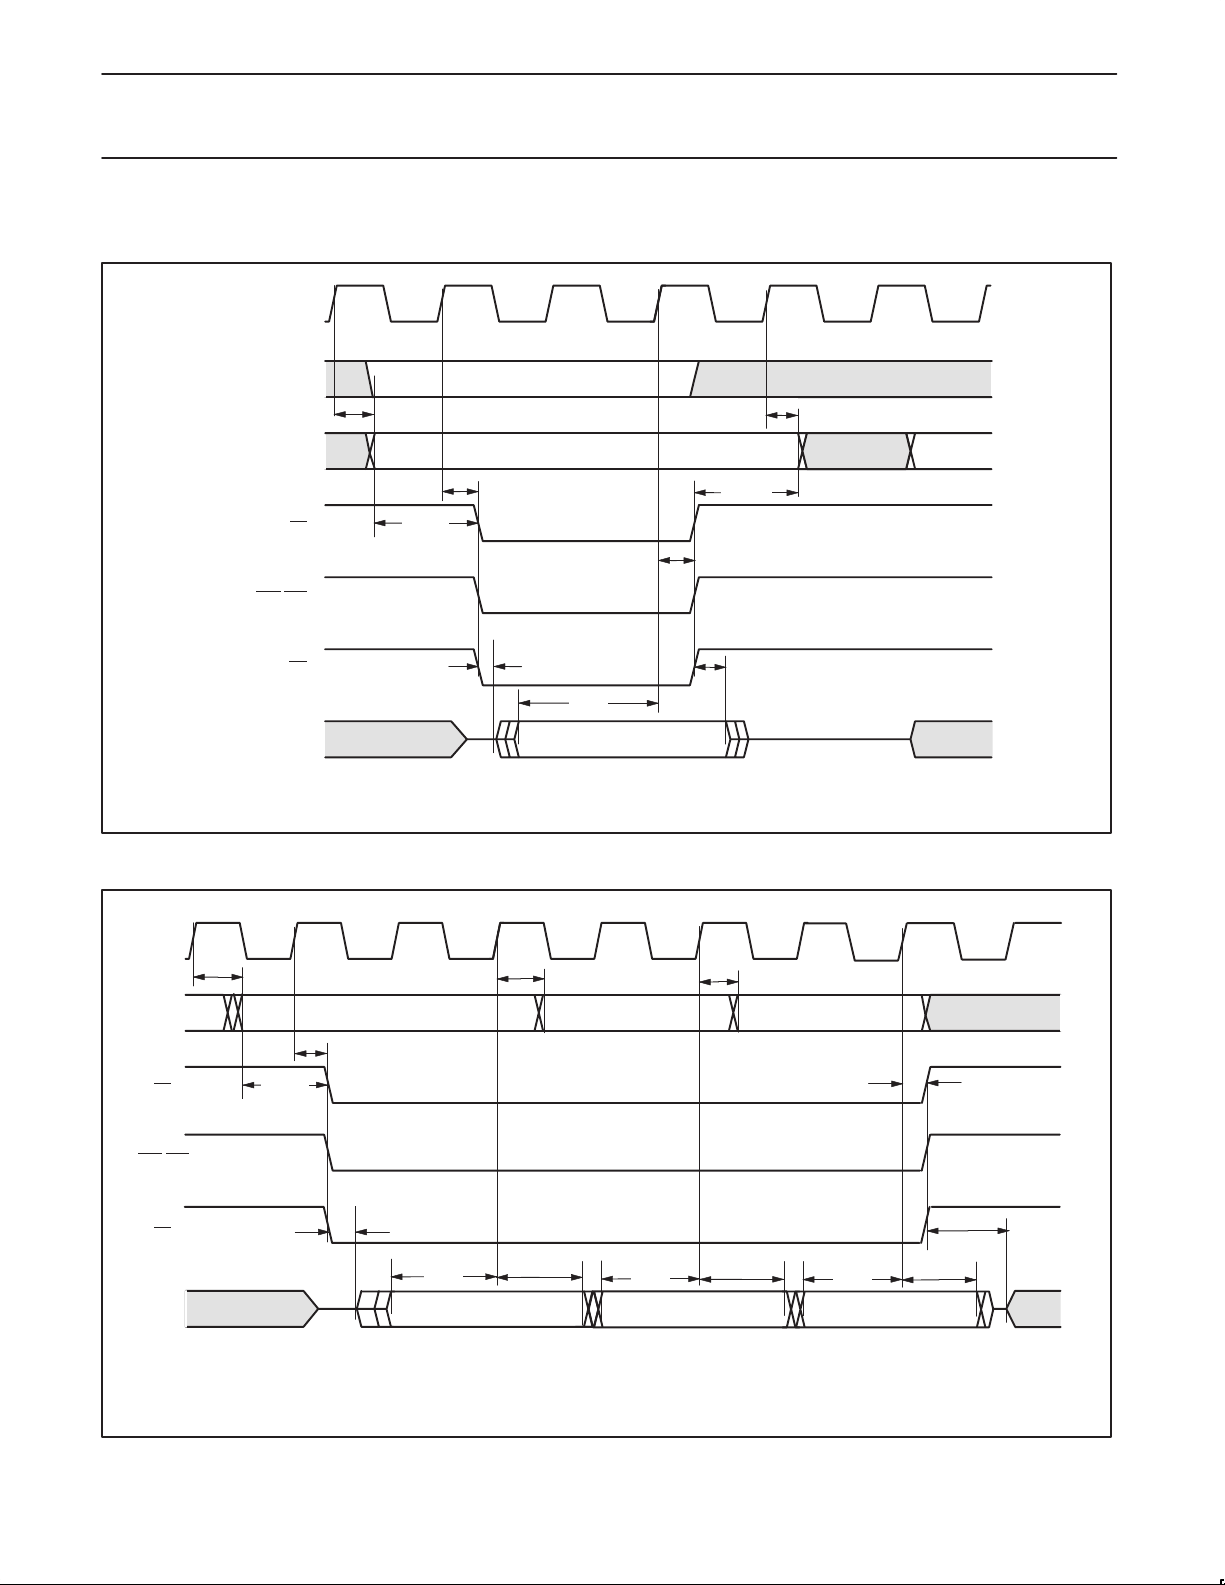
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
TIMING DIAGRAMS
All references to numbered Notes are to the notes following the AC Electrical Characteristics tables
ClkOut
A0
t
CHAV
A19–A1
t
CHSL
t
Note 3
AVSL
t
DIS
CS
BHE/BLE
OE
D15–D0
Note: On Generic Data Reads, A0 can terminate a full clock period before A19–A1, and therefore
should not be used on some peripheral devices.
Figure 7. Read on 16-Bit Bus
ClkOut
A[19:0]
t
CHAV
Address Address + 2 Address + 4
t
CHAV
t
CHSH
t
AHDR
t
DIH
(Note 2)
t
CHAV
t
CHAH
(Does Not Include A0)
SU01277
t
CHSL
t
CS
BHE/BLE
OE
D[15:0]
Note: The processor can prefetch from one to eight words.
Driven by XA
AVSL
Note 3
1999 Sep 24
t
DIH
t
DIS
Note 2
t
DIS
Figure 8. Burst Code Fetch on 16-Bit Bus
30
t
DIH
Note 2
t
CHSH
t
OHDE
t
DIH
t
DIS
(Note 2)
Driven
by XA
SU01131
Page 31
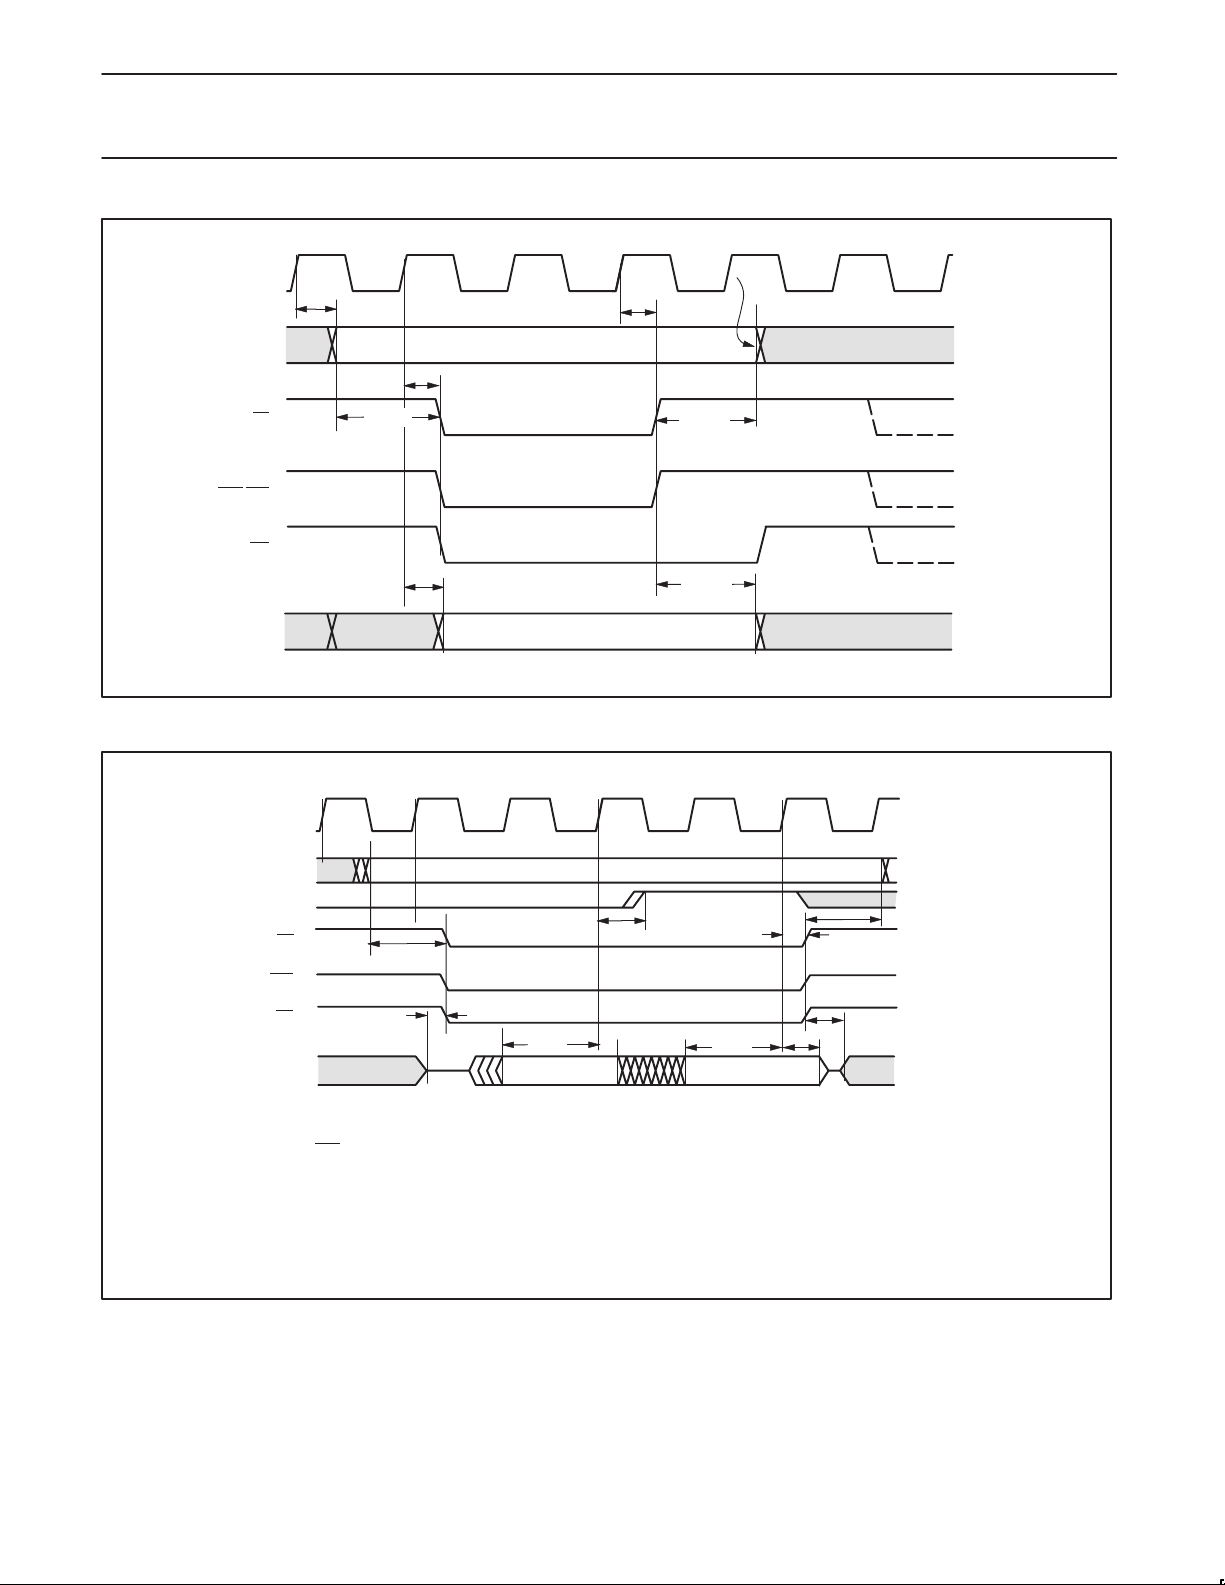
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
ClkOut
BHE/BLE
A
CS
WE
D
ClkOut
A19 – A1
CS
BLE
OE
D7 – D0
t
CHAV
t
CHDV
t
AVSL
t
CHSL
Note 1
t
CHSH
t
SHAH
t
SHDH
Figure 9. Write ( byte write on 8-bit bus, or all writes on 16-bit bus )
A0
t
CHSL
t
AVSL
Note 3
t
DIS
Driven by XA Driven by XA
Note 2
t
CHAV
t
CHSH
t
DIS
Note 2
t
DIH
t
OHDE
SU01278
t
AHDR
On all cycles on 8-bit bus, BHE remains high (inactive)
Note: On the external bus, ALL XA-H4 reads are 16-bit reads. If the CPU instruction only specifies 8-bits, then the CPU uses the appropriate byte, and discards the
WARNING: Some 8-bit I/O devices (especially FIFOS) cannot operate correctly with 2 bytes being read for a one byte read. The most common (and least expensive)
solution is to operate these 8-bit devices on a 16-bit bus, and access them in software on all odd byte (or all even byte) boundaries. An added benefit of this technique is that byte reads are faster than on an 8-bit bus, because only 1 word is fetched (a single read) instead of 2 consecutive bytes.
1999 Sep 24
extra byte. Thus, “8-Bit Reads” and “16-Bit Reads” appear to be identical on the bus. On an 8-bit bus, this will appear as two consecutive 8-bit reads even
though the CPU will only use one of the two bytes.
Figure 10. Read (16-Bit or 8-Bit) on 8 Bit Bus
31
SU01283
Page 32
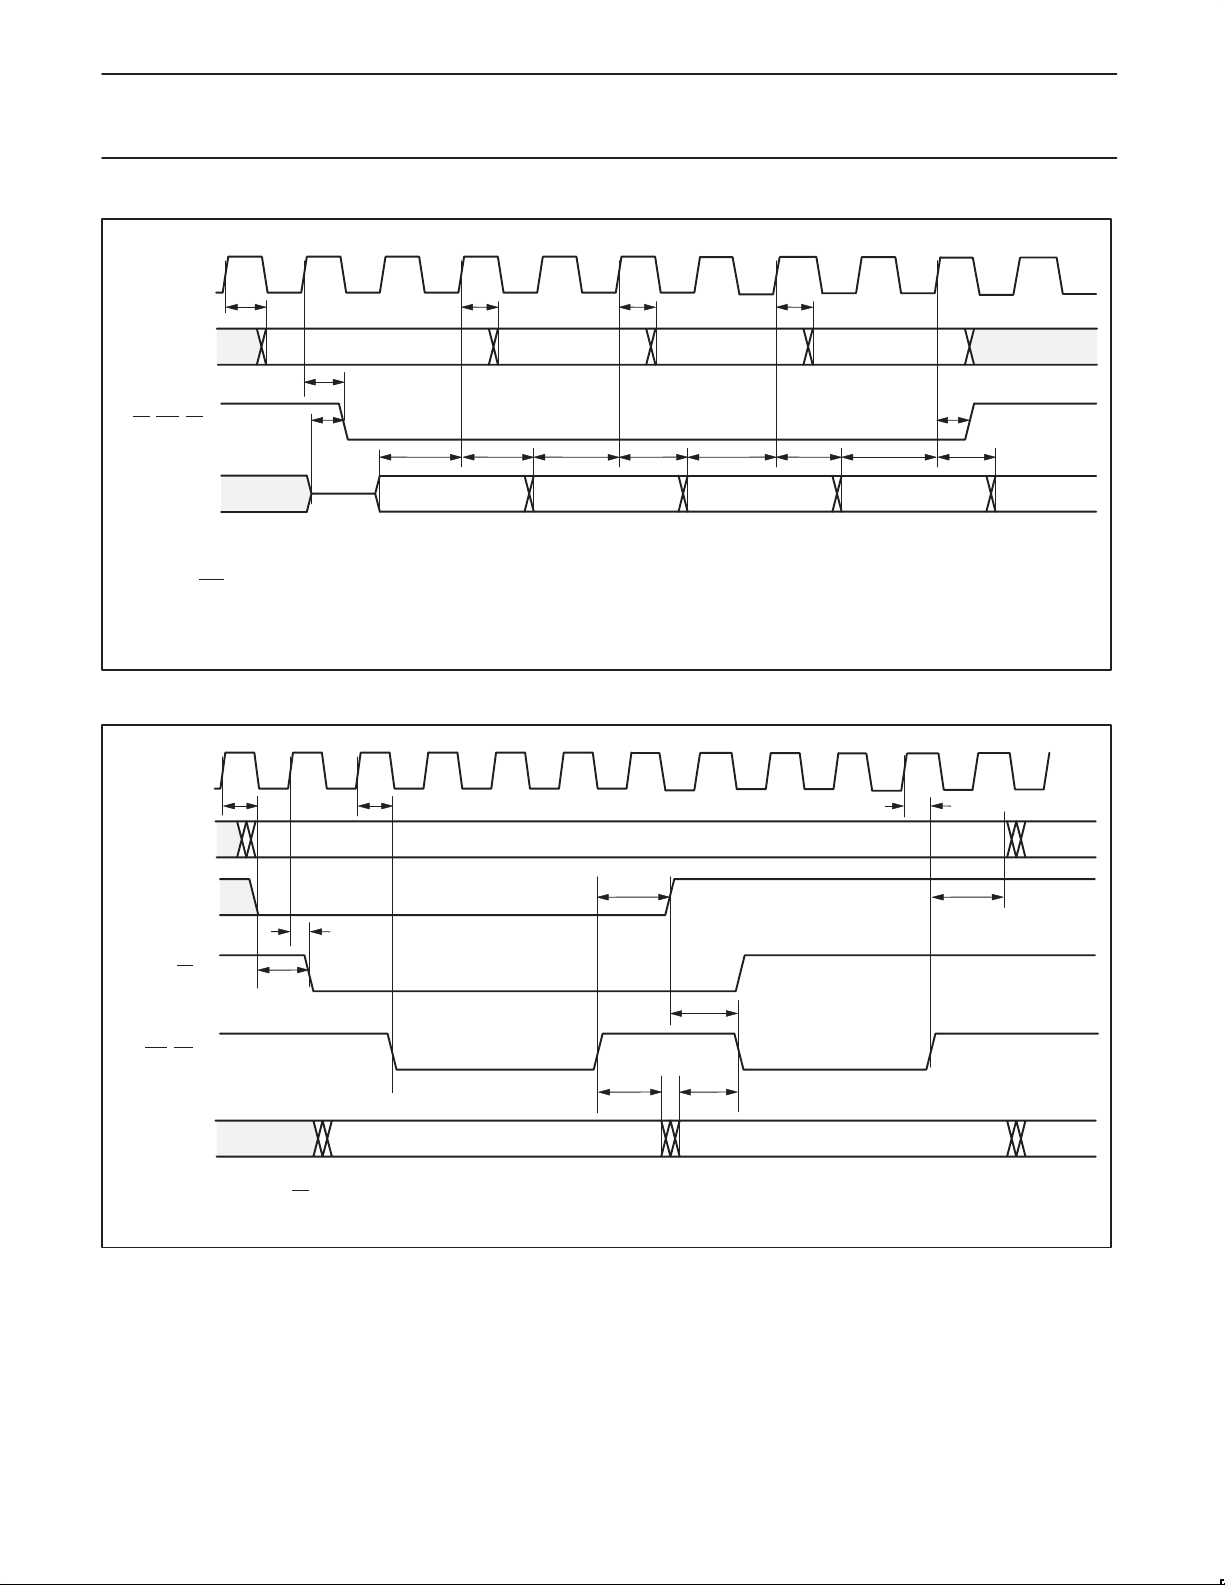
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
Clkout
t
CHAV
t
CHAV
t
CHAV
t
CHAV
Even Address Address + 1
t
CHAV
OE, BLE, CS
Note 3
t
DIS
t
DIH
t
DIS
t
DIH
Note 2 Note 2 Note 2 Note 2
D[7:0]
Note: BHE remains high (inactive) for all accesses on an 8-bit bus. A burst code fetch can be
from 1 to 8 words (1 word = 2 bytes), a 2 word fetch is shown here.
LS Byte
MS Byte LS Byte MS Byte
Figure 11. Burst Code Fetch on 8-bit bus
Clkout
t
A19 – A1
CHAV
A0
t
CHSL
t
CHSL
Address + 2 Address + 3
t
SHAH
t
DIS
t
DIH
t
DIS
t
SHAH
t
DIH
t
CHSH
t
CHSH
SU01245
BLE
, WE
D7 – D0
1999 Sep 24
CS
t
AVSL
Note. OE
is inactive during all writes.
t
SHDH
Figure 12. 16-Bit Write on 8-Bit Bus
32
t
AVSL
t
DVSL
SU01246
Page 33
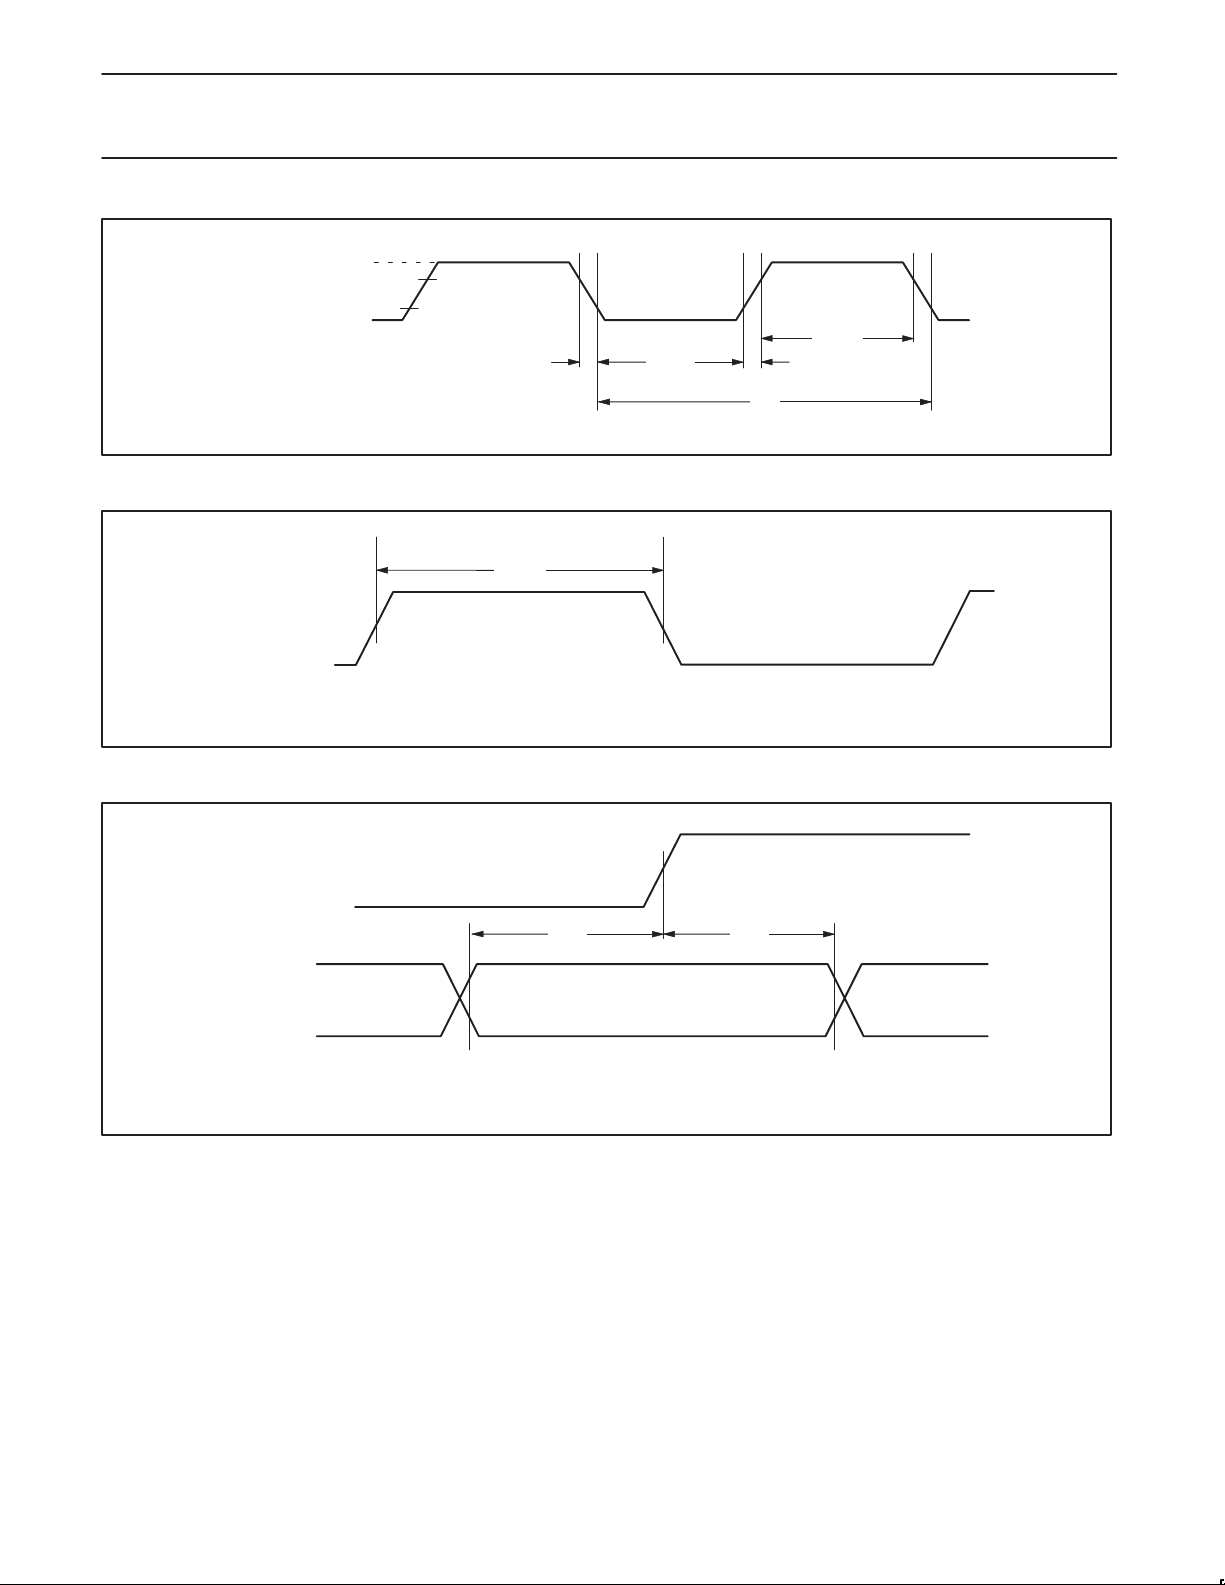
Philips Semiconductors Preliminary specification
XA-H3CMOS 16-bit highly integrated microcontroller
XTALIN
ClkOut
VDD – 0.5
0.45 V
0.2 V
0.7 V
DD
DD
– 0.1
t
CHCL
Figure 13. External Clock Input Drive
t
CODH
WARNING: ClkOut is specified into 40 pF max, do not overload.
Figure 14. ClkOut Duty Cycle
t
CLCX
t
CHCX
t
CLCH
t
C
SU01146
SU01147
ClkOut
WAIT
t
WS
tWS – Setup time of WAIT to rising edge of ClkOut.
tWH – Hold time of WAIT after ClkOut High.
Figure 15. External WAIT Pin T iming
t
WH
SU01148
1999 Sep 24
33
Page 34
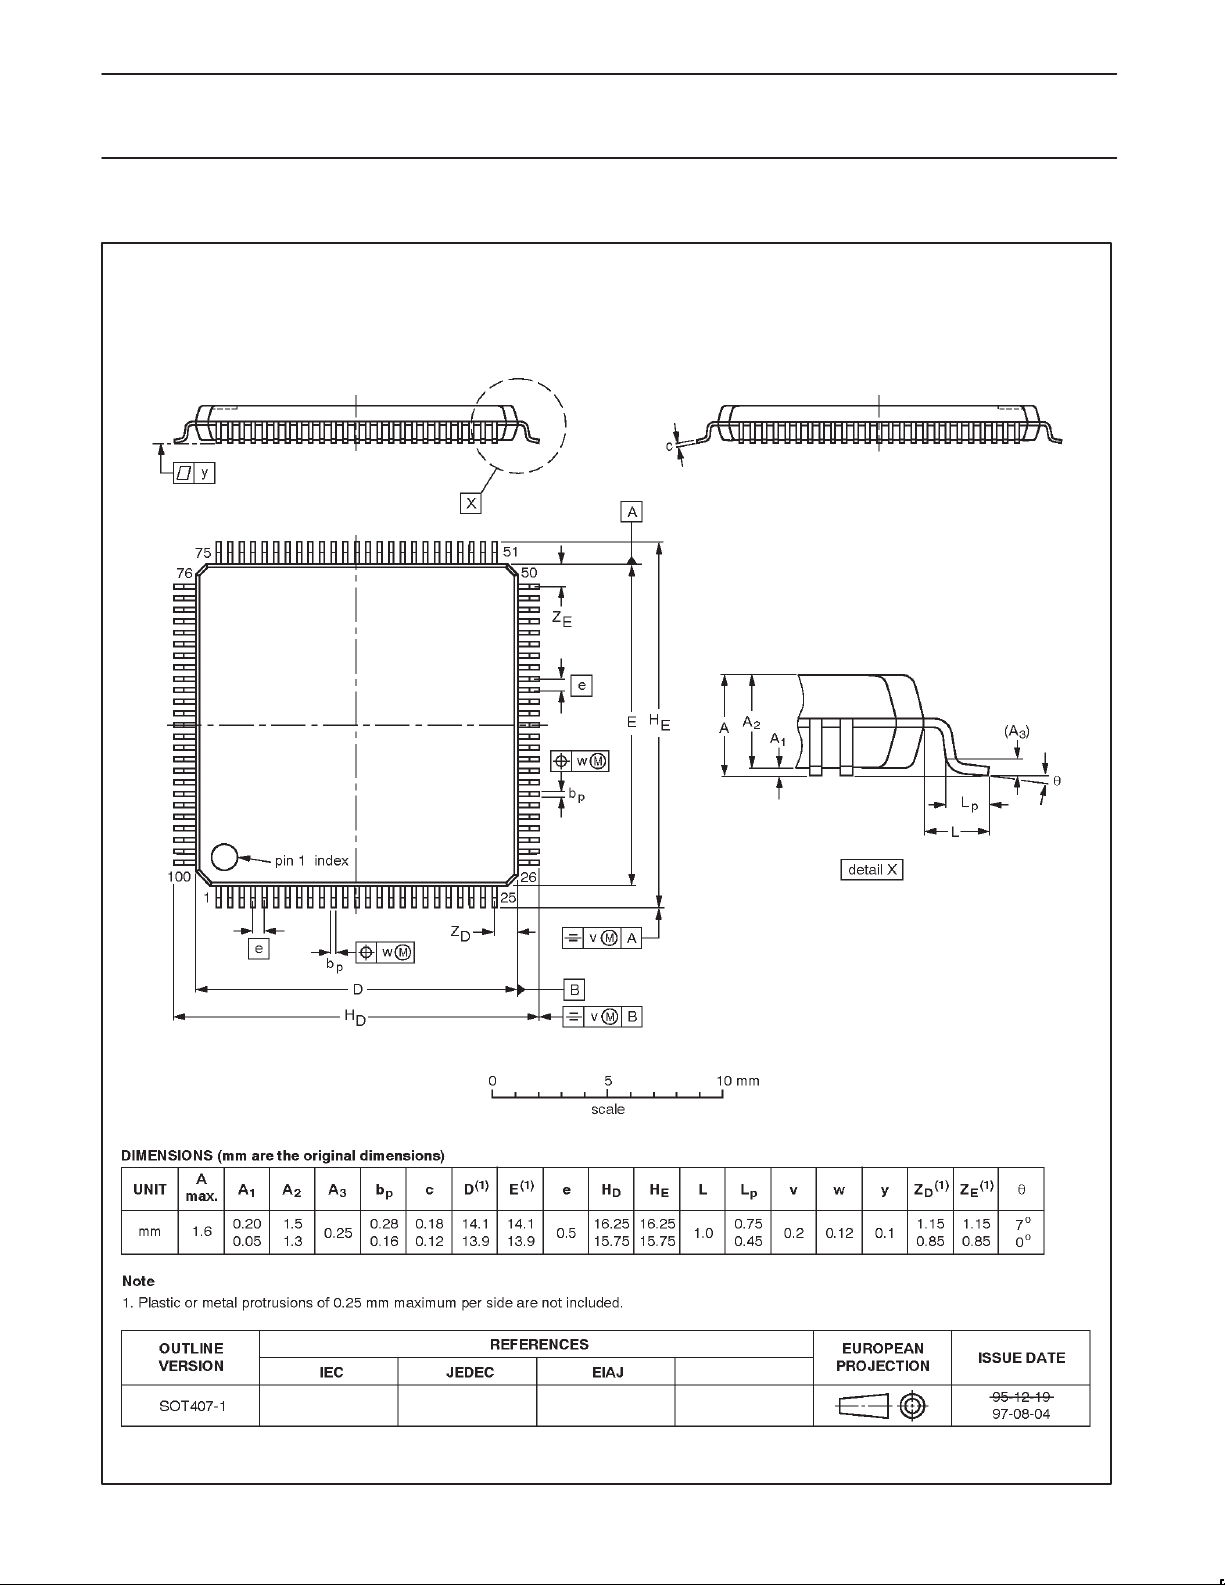
Philips Semiconductors Preliminary specification
CMOS 16-bit highly integrated microcontroller
LQFP100: plastic low profile quad flat package; 100 leads; body 14 x 14 x 1.4 mm SOT407-1
XA-H3
1999 Sep 24
34
Page 35
Philips Semiconductors Preliminary specification
CMOS 16-bit highly integrated microcontroller
NOTES
XA-H3
1999 Sep 24
35
Page 36
Philips Semiconductors Preliminary specification
CMOS 16-bit highly integrated microcontroller
Data sheet status
Data sheet
status
Objective
specification
Preliminary
specification
Product
specification
Product
status
Development
Qualification
Production
Definition
This data sheet contains the design target or goal specifications for product development.
Specification may change in any manner without notice.
This data sheet contains preliminary data, and supplementary data will be published at a later date.
Philips Semiconductors reserves the right to make changes at any time without notice in order to
improve design and supply the best possible product.
This data sheet contains final specifications. Philips Semiconductors reserves the right to make
changes at any time without notice in order to improve design and supply the best possible product.
[1]
XA-H3
[1] Please consult the most recently issued datasheet before initiating or completing a design.
Definitions
Short-form specification — The data in a short-form specification is extracted from a full data sheet with the same type number and title. For
detailed information see the relevant data sheet or data handbook.
Limiting values definition — Limiting values given are in accordance with the Absolute Maximum Rating System (IEC 134). Stress above one
or more of the limiting values may cause permanent damage to the device. These are stress ratings only and operation of the device at these or
at any other conditions above those given in the Characteristics sections of the specification is not implied. Exposure to limiting values for extended
periods may affect device reliability.
Application information — Applications that are described herein for any of these products are for illustrative purposes only. Philips
Semiconductors make no representation or warranty that such applications will be suitable for the specified use without further testing or
modification.
Disclaimers
Life support — These products are not designed for use in life support appliances, devices or systems where malfunction of these products can
reasonably be expected to result in personal injury . Philips Semiconductors customers using or selling these products for use in such applications
do so at their own risk and agree to fully indemnify Philips Semiconductors for any damages resulting from such application.
Right to make changes — Philips Semiconductors reserves the right to make changes, without notice, in the products, including circuits, standard
cells, and/or software, described or contained herein in order to improve design and/or performance. Philips Semiconductors assumes no
responsibility or liability for the use of any of these products, conveys no license or title under any patent, copyright, or mask work right to these
products, and makes no representations or warranties that these products are free from patent, copyright, or mask work right infringement, unless
otherwise specified.
Philips Semiconductors
811 East Arques Avenue
P.O. Box 3409
Sunnyvale, California 94088–3409
Telephone 800-234-7381
Copyright Philips Electronics North America Corporation 1999
All rights reserved. Printed in U.S.A.
Date of release: 09-99
Document order number: 9397 750 06431
1999 Sep 24
36
 Loading...