

Page 1
W83977TF
WINBOND I/O
Page 2
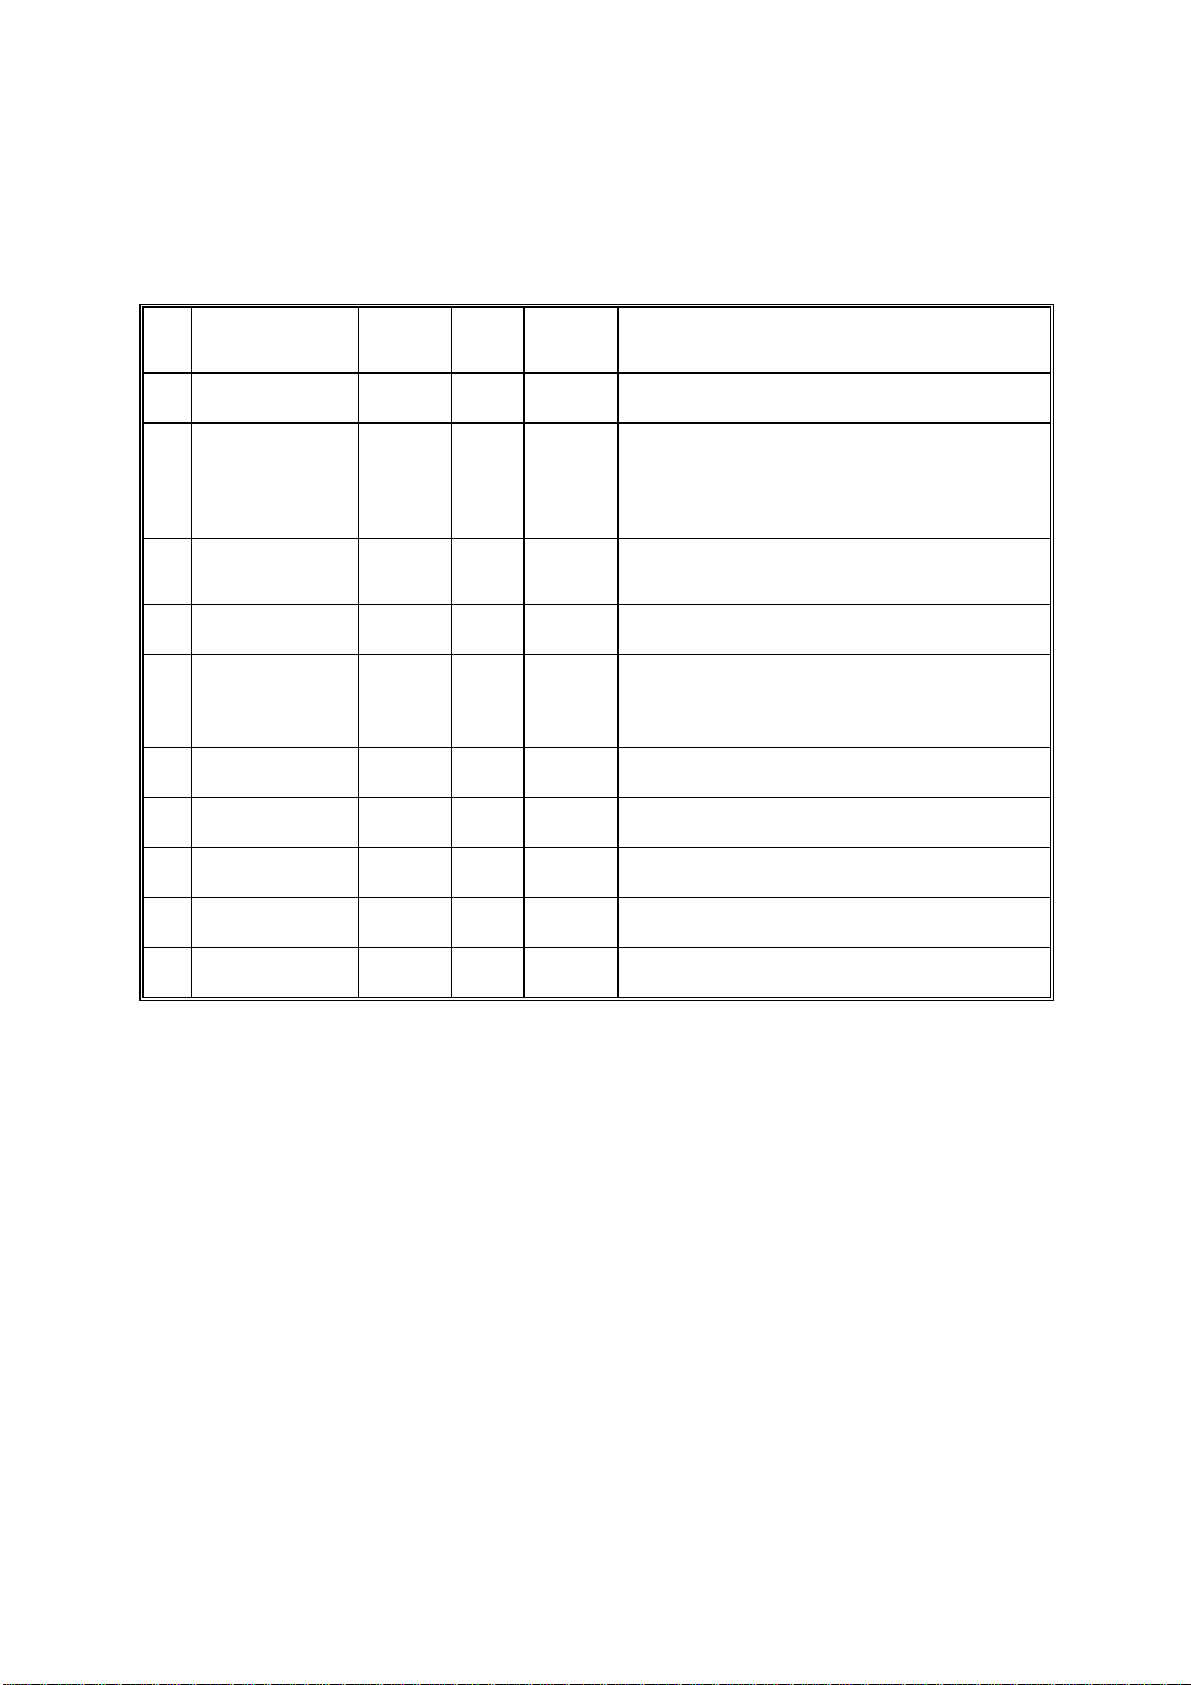
W83977TF Data Sheet Revision History
Pages Dates Versi
1 n.a. 05/20/97 0.50 First published.
IV,V,6,7,14,49,5
2
5,69-80,87-96,
103,113, 117,
118,122, 128,
149
3 III,3,68,134,
146,148; 64-67
4 P101,101.1,102 11/18/97 0.61 Register correction
P1,3,49,62,64,
5
67,71,73,74,
100,117,119,
120,129
6
7
8
07/01/97 0.51 Typo correction and data calibrated
07/20/97 0.60 Explanation of OnNow/ security wake-up
03/19/98 0.62 Typo correction and data calibrated
on
Version
on Web
Main Contents
functions; Repagenating
9
10
Please note that all data and specifications are subject to change without notice. All
the trade marks of products and companies mentioned in this data sheet belong to
their respective owners.
LIFE SUPPORT APPLICATIONS
These products are not designed for use in life support appliances, devices, or
systems where malfunction of these products can reasonably be expected to result
in personal injury. Winbond customers using or selling these products for use in such
applications do so at their own risk and agree to fully indemnify Winbond for any
damages resulting from such improper use or sales.
Page 3
W83977TF
TABLE OF CONTENTS
GENERAL DESCRIPTION.......................................................................................................1
FEATURES....................................................................................................................................2
PIN CONFIGURATION .............................................................................................................4
1. PIN DESCRIPTION................................................................................................................5
1.1 HOST INTERFACE.....................................................................................................................................5
1.2 GENERAL PURPOSE I/O PORT...............................................................................................................7
1.3 SERIAL PORT INTERFACE......................................................................................................................8
1.4 INFRARED INTERFACE...........................................................................................................................9
1.5 MULTI-MODE PARALLEL PORT...........................................................................................................9
1.6 FDC INTERFACE......................................................................................................................................14
1.7 KBC INTERFACE......................................................................................................................................15
1.8 POWER PINS.............................................................................................................................................16
1.9 ACPI INTERFACE.....................................................................................................................................16
2. FDC FUNCTIONAL DESCRIPTION................................................................................17
2.1 W83977TF FDC.........................................................................................................................................17
2.1.1 AT INTERFACE.............................................................................................................................17
2.1.2 FIFO (DATA)..................................................................................................................................17
2.1.3 DATA SEPARATOR.....................................................................................................................18
2.1.4 WRITE PRECOMPENSATION ...................................................................................................18
2.1.5 PERPENDICULAR RECORDING MODE.................................................................................18
2.1.6 FDC CORE......................................................................................................................................19
2.1.7 FDC COMMANDS ........................................................................................................................19
2.2 REGISTER DESCRIPTIONS...................................................................................................................29
2.2.1 STATUS REGISTER A (SA REGISTER) (READ BASE ADDRESS + 0).............................29
2.2.2 STATUS REGISTER B (SB REGISTER) (READ BASE ADDRESS + 1) .............................31
2.2.3 DIGITAL OUTPUT REGISTER (DO REGISTER) (WRITE BASE ADDRESS + 2)............33
2.2.4 TAPE DRIVE REGISTER (TD REGISTER) (READ BASE ADDRESS + 3)........................33
2.2.5 MAIN STATUS REGISTER (MS REGISTER) (READ BASE ADDRESS + 4)....................34
Publication Release Date: March 1998
- I - Revision 0.62
Page 4
W83977TF
2.2.6 DATA RATE REGISTER (DR REGISTER) (WRITE BASE ADDRESS + 4).......................34
2.2.7 FIFO REGISTER (R/W BASE ADDRESS + 5)..........................................................................36
2.2.8 DIGITAL INPUT REGISTER (DI REGISTER) (READ BASE ADDRESS + 7)....................38
2.2.9 CONFIGURATION CONTROL REGISTER (CC REGISTER)
(WRITE BASE ADDRESS + 7)...................................................................................................39
3. UART PORT............................................................................................................................40
3.1 UNIVERSAL ASYNCHRONOUS RECEIVER/TRANSMITTER (UART A, UART B)..................40
3.2 REGISTER ADDRESS..............................................................................................................................40
3.2.1 UART CONTROL REGISTER (UCR) (READ/WRITE)...........................................................40
3.2.2 UART STATUS REGISTER (USR) (READ/WRITE)...............................................................42
3.2.3 HANDSHAKE CONTROL REGISTER (HCR) (READ/WRITE) ............................................43
3.2.4 HANDSHAKE STATUS REGISTER (HSR) (READ/WRITE).................................................44
3.2.5 UART FIFO CONTROL REGISTER (UFR) (WRITE ONLY) .................................................45
3.2.6 INTERRUPT STATUS REGISTER (ISR) (READ ONLY).......................................................46
3.2.7 INTERRUPT CONTROL REGISTER (ICR) (READ/WRITE).................................................47
3.2.8 PROGRAMMABLE BAUD GENERATOR (BLL/BHL) (READ/WRITE) .............................47
3.2.9 USER-DEFINED REGISTER (UDR) (READ/WRITE).............................................................48
4. INFRARED (IR) PORT.........................................................................................................49
5. PARALLEL PORT ...............................................................................................................49
5.1 PRINTER INTERFACE LOGIC...............................................................................................................49
5.2 ENHANCED PARALLEL PORT (EPP)..................................................................................................50
5.2.1 DATA SWAPPER ..........................................................................................................................51
5.2.2 PRINTER STATUS BUFFER.......................................................................................................51
5.2.3 PRINTER CONTROL LATCH AND PRINTER CONTROL SWAPPER...............................52
5.2.4 EPP ADDRESS PORT...................................................................................................................52
5.2.5 EPP DATA PORT 0-3....................................................................................................................53
5.2.6 BIT MAP OF PARALLEL PORT AND EPP REGISTERS .......................................................53
5.2.7 EPP PIN DESCRIPTIONS ............................................................................................................54
5.2.8 EPP OPERATION..........................................................................................................................54
5.3 EXTENDED CAPABILITIES PARALLEL (ECP) PORT.....................................................................55
5.3.1 ECP REGISTER AND MODE DEFINITIONS...........................................................................55
5.3.2 DATA AND ECPAFIFO PORT....................................................................................................56
5.3.3 DEVICE STATUS REGISTER (DSR).........................................................................................56
5.3.4 DEVICE CONTROL REGISTER (DCR) ....................................................................................57
Publication Release Date: March 1998
- II - Revision 0.62
Page 5
W83977TF
5.3.5 CFIFO (PARALLEL PORT DATA FIFO) MODE = 010...........................................................58
5.3.6 ECPDFIFO (ECP DATA FIFO) MODE = 011............................................................................58
5.3.7 TFIFO (TEST FIFO MODE) MODE = 110.................................................................................58
5.3.8 CNFGA (CONFIGURATION REGISTER A) MODE = 111 ....................................................58
5.3.9 CNFGB (CONFIGURATION REGISTER B) MODE = 111 .....................................................58
5.3.10 ECR (EXTENDED CONTROL REGISTER) MODE = ALL....................................................59
5.3.11 BIT MAP OF ECP PORT REGISTERS.......................................................................................60
5.3.12 ECP PIN DESCRIPTIONS............................................................................................................61
5.3.13 ECP OPERATION..........................................................................................................................62
5.3.14 FIFO OPERATION ........................................................................................................................62
5.3.15 DMA TRANSFERS........................................................................................................................63
5.3.16 PROGRAMMED I/O (NON-DMA) MODE................................................................................63
5.4 EXTENSION FDD MODE (EXTFDD)...................................................................................................63
5.5 EXTENSION 2FDD MODE (EXT2FDD)..............................................................................................63
6. KEYBOARD CONTROLLER.............................................................................................64
6.1 OUTPUT BUFFER ....................................................................................................................................64
6.2 INPUT BUFFER.........................................................................................................................................64
6.3 STATUS REGISTER.................................................................................................................................65
6.4 COMMANDS .............................................................................................................................................65
6.5 HARDWARE GATEA20/KEYBOARD RESET CONTROL LOGIC .................................................67
6.5.1 KB CONTROL REGISTER (LOGIC DEVICE 5, CR-F0).........................................................67
6.5.2 PORT 92 CONTROL REGISTER (DEFAULT VALUE = 0X24)............................................67
6.4 ONNOW / SECURITY KEYBOARD AND MOUSE WAKE-UP ......................................................68
7. GENERAL PURPOSE I/O....................................................................................................69
7.1 BASIC I/O FUNCTIONS...........................................................................................................................71
7.2 ALTERNATE I/O FUNCTIONS..............................................................................................................73
7.2.1 INTERRUPT STEERING..............................................................................................................73
7.2.2 WATCH DOG TIMER OUTPUT.................................................................................................74
7.2.3 POWER LED...................................................................................................................................74
7.2.4 GENERAL PURPOSE ADDRESS DECODER..........................................................................74
7.2.5 GENERAL PURPOSE WRITE STROBE....................................................................................74
8. PLUG AND PLAY CONFIGURATION ............................................................................75
8.1 COMPATIBLE PNP...................................................................................................................................75
8.1.1 EXTENDED FUNCTION REGISTERS......................................................................................75
Publication Release Date: March 1998
- III - Revision 0.62
Page 6
W83977TF
8.1.2 EXTENDED FUNCTIONS ENABLE REGISTERS (EFERS) .................................................76
8.1.3 EXTENDED FUNCTION INDEX REGISTERS (EFIRS), EXTENDED FUNCTION
DATA REGISTERS(EFDRS).......................................................................................................76
9. ACPI REGISTERS FEATURES.........................................................................................77
9.1 SMI TO SCI/SCI TO SMI AND BUS MASTER....................................................................................78
9.2 POWER MANAGEMENT TIMER..........................................................................................................79
9.3 ACPI REGISTERS (ACPIRS)...................................................................................................................80
9.3.1 POWER MANAGEMENT 1 STATUS REGISTER 1 (PM1STS1)..........................................80
9.3.2 POWER MANAGEMENT 1 STATUS REGISTER 2 (PM1STS2)..........................................81
9.3.3 POWER MANAGEMENT 1 ENABLE REGISTER 1(PM1EN1) ............................................82
9.3.4 POWER MANAGEMENT 1 ENABLE REGISTER 2 (PM1EN2)...........................................82
9.3.5 POWER MANAGEMENT 1 CONTROL REGISTER 1 (PM1CTL1)......................................83
9.3.6 POWER MANAGEMENT 1 CONTROL REGISTER 2 (PM1CTL2)......................................83
9.3.7 POWER MANAGEMENT 1 CONTROL REGISTER 3 (PM1CTL3)......................................84
9.3.8 POWER MANAGEMENT 1 CONTROL REGISTER 4 (PM1CTL4)......................................84
9.3.9 POWER MANAGEMENT 1 TIMER 1 (PM1TMR1) ................................................................85
9.3.10 POWER MANAGEMENT 1 TIMER 2 (PM1TMR2) ................................................................85
9.3.11 POWER MANAGEMENT 1 TIMER 3 (PM1TMR3) ................................................................86
9.3.12 POWER MANAGEMENT 1 TIMER 4 (PM1TMR4) ................................................................87
9.3.13 GENERAL PURPOSE EVENT 0 STATUS REGISTER 1 (GP0STS1)...................................87
9.3.14 GENERAL PURPOSE EVENT 0 STATUS REGISTER 2 (GP0STS2)...................................88
9.3.15 GENERAL PURPOSE EVENT 0 ENABLE REGISTER 1 (GP0EN1)....................................89
9.3.16 GENERAL PURPOSE EVENT 0 ENABLE REGISTER 2 (GP0EN2)....................................89
9.3.17 GENERAL PURPOSE EVENT 1 STATUS REGISTER 1 (GP1STS1)...................................90
9.3.18 GENERAL PURPOSE EVENT 1 STATUS REGISTER 2 (GP1STS2)...................................90
9.3.19 GENERAL PURPOSE EVENT 1 ENABLE REGISTER 1 (GP1EN1)....................................91
9.3.20 GENERAL PURPOSE EVENT 1 ENABLE REGISTER 2 (GP1EN2)....................................91
9.3.21 BIT MAP CONFIGURATION REGISTERS...............................................................................92
10. SERIAL IRQ.........................................................................................................................93
10.1 START FRAME .........................................................................................................................................94
10.2 IRQ/DATA FRAME...................................................................................................................................94
10.3 STOP FRAME............................................................................................................................................94
10.4 RESET AND INITIALIZATION..............................................................................................................95
11. CONFIGURATION REGISTER.......................................................................................96
Publication Release Date: March 1998
- IV - Revision 0.62
Page 7
W83977TF
11.1 CHIP (GLOBAL) CONTROL REGISTER..............................................................................................96
11.2 LOGICAL DEVICE 0 (FDC)...................................................................................................................100
11.3 LOGICAL DEVICE 1 (PARALLEL PORT)..........................................................................................103
11.4 LOGICAL DEVICE 2 (UART A)¢) ........................................................................................................104
11.5 LOGICAL DEVICE 3 (UART B) ...........................................................................................................104
11.6 LOGICAL DEVICE 5 (KBC)..................................................................................................................106
11.7 LOGICAL DEVICE 7 (GP I/O PORT I).................................................................................................107
11.8 LOGICAL DEVICE 8 (GP I/O PORT II)...............................................................................................110
11.9 LOGICAL DEVICE 9 (GP I/O PORT III)..............................................................................................114
11.10 LOGICAL DEVICE A (ACPI)................................................................................................................117
12. SPECIFICATIONS............................................................................................................123
12.1 ABSOLUTE MAXIMUM RATINGS ....................................................................................................123
12.2 DC CHARACTERISTICS.......................................................................................................................123
12.3 AC CHARACTERISTICS.......................................................................................................................127
12.3.1 FDC: DATA RATE = 1 MB, 500 KB, 300 KB, 250 KB/SEC...............................................127
12.3.2 UART/PARALLEL PORT........................................................................................................129
12.3.3 PARALLEL PORT MODE PARAMETERS..........................................................................129
12.3.4 EPP DATA OR ADDRESS READ CYCLE TIMING PARAMETERS..............................130
12.3.5 EPP DATA OR ADDRESS WRITE CYCLE TIMING PARAMETERS ............................131
12.3.6 PARALLEL PORT FIFO TIMING PARAMETERS..............................................................132
12.3.7 ECP PARALLEL PORT FORWARD TIMING PARAMETERS .........................................132
12.3.8 ECP PARALLEL PORT REVERSE TIMING PARAMETERS...........................................132
12.3.9 KBC TIMING PARAMETERS................................................................................................133
12.3.10 GPIO TIMING PARAMETERS................................................................................................134
13. TIMING WAVEFORMS..................................................................................................135
13.1 FDC............................................................................................................................................................135
13.2 UART/PARALLEL...................................................................................................................................136
13.2.1 MODEM CONTROL TIMING ................................................................................................137
13.3 PARALLEL PORT...................................................................................................................................138
13.3.1 PARALLEL PORT TIMING.....................................................................................................138
13.3.2 EPP DATA OR ADDRESS READ CYCLE (EPP VERSION 1.9)......................................139
13.3.3 EPP DATA OR ADDRESS WRITE CYCLE (EPP VERSION 1.9)....................................140
13.3.4 EPP DATA OR ADDRESS READ CYCLE (EPP VERSION 1.7)......................................141
13.3.5 EPP DATA OR ADDRESS WRITE CYCLE (EPP VERSION 1.7)....................................142
13.3.6 PARALLEL PORT FIFO TIMING...........................................................................................142
Publication Release Date: March 1998
- V - Revision 0.62
Page 8
W83977TF
13.3.7 ECP PARALLEL PORT FORWARD TIMING......................................................................143
13.3.8 ECP PARALLEL PORT REVERSE TIMING........................................................................143
13.4 KBC............................................................................................................................................................144
13.4.1 WRITE CYCLE TIMING..........................................................................................................144
13.4.2 READ CYCLE TIMING...........................................................................................................144
13.4.3 SEND DATA TO K/B...............................................................................................................144
13.4.4 RECEIVE DATA FROM K/B ..................................................................................................145
13.4.5 INPUT CLOCK..........................................................................................................................145
13.4.6 SEND DATA TO MOUSE.......................................................................................................145
13.4.7 RECEIVE DATA FROM MOUSE..........................................................................................145
13.5 GPIO WRITE TIMING DIAGRAM.......................................................................................................146
13.6 MASTER RESET (MR) TIMING...........................................................................................................146
14. APPLICATION CIRCUITS.............................................................................................147
14.1 PARALLEL PORT EXTENSION FDD.................................................................................................147
14.2 PARALLEL PORT EXTENSION 2FDD...............................................................................................147
14.3 FOUR FDD MODE..................................................................................................................................148
15. ORDERING INFORMATION.........................................................................................148
16. HOW TO READ THE TOP MARKING .......................................................................148
17. PACKAGE DIMENSIONS...............................................................................................149
Publication Release Date: March 1998
- VI - Revision 0.62
Page 9
W83977TF
SMI
SCI
WINBOND I/O
GENERAL DESCRIPTION
The W83977TF is an evolving product from Winbond's most popular I/O chip W83877F --- which
integrates the disk drive adapter, serial port (UART), IrDA 1.0 SIR, parallel port, configurable plug-and-
play registers for the whole chip --- plus additional powerful features:
with PS/2 mouse support, 23 general purpose I/O ports, full 16-bit address decoding, OnNow keyboard
wake-up, OnNow mouse wake-up.
The disk drive adapter functions of W83977TF include a floppy disk drive controller compatible with the
industry standard 82077/ 765, data separator, write pre-compensation circuit, decode logic, data rate
selection, clock generator, drive interface control logic, and interrupt and DMA logic. The wide range of
functions integrated into the W83977TF greatly reduces the number of components required for
interfacing with floppy disk drives. The W83977TF supports four 360K, 720K, 1.2M, 1.44M, or 2.88M
disk drives and data transfer rates of 250 Kb/s, 300 Kb/s, 500 Kb/s,1 Mb/s, and 2 Mb/s.
The W83977TF provides two high-speed serial communication ports (UARTs), one of which supports
serial Infrared communication. Each UART includes a 16-byte send/receive FIFO, a programmable
baud rate generator, complete modem control capability, and a processor interrupt system. Both
UARTs provide legacy speed with baud rate up to 115.2k bps and also advanced speed with baud rates
230k, 460k
of
The W83977TF supports one PC-compatible printer port (SPP), Bi-directional Printer port (BPP) and
also Enhanced Parallel Port (EPP) and Extended Capabilities Port (ECP). Through the printer port
interface pins, also available are: Extension FDD Mode and Extension 2FDD Mode allowing one or two
external floppy disk drives to be connected.
The configuration registers support mode selection, function enable/disable, and power down function
selection. Furthermore, the configurable PnP features are compatible with the plug-and-play feature
demand of Windows 95TM, which makes system resource allocation more efficient than ever.
W83977TF provides functions that comply with
which includes support of legacy and ACPI power management through
W83977TF also has auto power management to reduce power consumption.
The keyboard controller is based on 8042 compatible instruction set with a 2K Byte programmable ROM
and a 256-Byte RAM bank. Keyboard BIOS firmware is available with optional AMIKEY
MultiKey/42TM, or customer code.
The W83977TF provides a set of flexible I/O control functions to the system designer through a set of
General Purpose I/O ports. These GPIO ports may serve as simple I/O or may be individually
configured to provide a predefined alternate function.
W83977TF is made to fully comply with
I/O space resource are flexible to adjust to meet ISA PnP requirement. Moreover W83977TF is made to
meet the specification of PC97's requirement in the power management:
Power Management).
Another benifit is that W83977TF has the same pin assignment as W83977AF, W83977F, W83977ATF.
This makes the design very flexible.
921k bps
, or
which support higher speed modems.
ACPI (Advanced Configuration and Power Interface
Microsoft PC97 Hardware Design Guide
ACPI
, 8042 keyboard controller
or
ACPI
function pins.
TM
. IRQs, DMAs, and
DPM
and
-
2, Phoenix
(Device
),
Publication Release Date: April 1998
-1- Preliminary Revision 0.62
Page 10
W83977TF
SCI
PRELIMINARY
FEATURES
General
•
Plug & Play 1.0A compatible
• Support 13 IRQs, 4 DMA channels, full 16-bit address decoding
•
Capable of ISA Bus IRQ Sharing
•
Compliant with
•
Support
•
Report ACPI status interrupt by
• Programmable configuration settings
•
Single 24/48 Mhz clock input
FDC
•
Compatible with IBM PC AT disk drive systems
•
Variable write pre-compensation with track selectable capability
• Support vertical recording format
•
DMA enable logic
•
16-byte data FIFOs
•
Support floppy disk drives and tape drives
•
Detects all overrun and underrun conditions
•
Built-in address mark detection circuit to simplify the read electronics
•
FDD anti-virus functions with software write protect and FDD write enable signal (write data signal was
forced to be inactive)
•
Support up to four 3.5-inch or 5.25-inch floppy disk drives
•
Completely compatible with industry standard 82077
•
360K/720K/1.2M/1.44M/2.88M format; 250K, 300K, 500K, 1M, 2M bps data transfer rate
•
Support
Microsoft PC97
DPM
(Device Power Management),
3-mode FDD, and its Win95 driver
Hardware Design Guide
ACPI
signal issued from any of the 13 IQRs pins or GPIO xx
UART
•
Two high-speed 16550 compatible UARTs with 16-byte send/receive FIFOs
•
MIDI compatible
•
Fully programmable serial-interface characteristics:
--- 5, 6, 7 or 8-bit characters
--- Even, odd or no parity bit generation/detection
--- 1, 1.5 or 2 stop bits generation
•
Internal diagnostic capabilities:
--- Loop-back controls for communications link fault isolation
--- Break, parity, overrun, framing error simulation
•
Programmable baud generator allows division of 1.8461 Mhz and 24 Mhz by 1 to (216-1)
Maximum baud rate up to
-2- Revision 0.62
921k bps
for 14.769 Mhz and 1.5M bps for 24 Mhz
Publication Release Date: April 1998
Page 11
W83977TF
PRELIMINARY
Infrared
•
Support IrDA version 1.0 SIR protocol with maximum baud rate up to 115.2K bps
•
Support SHARP ASK-IR protocol with maximum baud rate up to 57,600 bps
• Support S/W driver for Windows95TM and Windows98TM (MemphisTM)
Parallel Port
•
Compatible with IBM parallel port
•
Support PS/2 compatible bi-directional parallel port
•
Support Enhanced Parallel Port (EPP) − Compatible with IEEE 1284 specification
•
Support Extended Capabilities Port (ECP) − Compatible with IEEE 1284 specification
•
Extension FDD mode supports disk drive B; and Extension 2FDD mode supports disk drives A and B
through parallel port
•
Enhanced printer port back-drive current protection
Keyboard Controller
TM
•
8042 based with optional F/W from AMIKKEYTM-2, Phoenix MultiKey/42
with 2K bytes of programmable ROM, and 256 bytes of RAM
•
Asynchronous Access to Two Data Registers and One status Register
•
Software compatibility with the 8042 and PC87911 microcontrollers
•
Support PS/2 mouse
•
Support port 92
• Support both interrupt and polling modes
•
Fast Gate A20 and Hardware Keyboard Reset
•
8 Bit Timer/ Counter
•
Support binary and BCD arithmetic
• 6MHz, 8 MHz, 12 MHz, or 16 MHz operating frequency
or customer code
General Purpose I/O Ports
•
23 programmable general purpose I/O ports; 3 dedicate, 20 optional
•
General purpose I/O ports can serve as simple I/O ports, interrupt steering inputs, watching dog timer
output, power LED output, infrared I/O pins, general purpose address decoder, KBC control I/O pins
OnNow Funtions
•
Keyboard wake-up by programmable keys
•
Mouse wake-up by programmable buttons
Package
•
128-pin PQFP
Publication Release Date: April 1998
-3 - Revision 0.62
Page 12
W83977TF
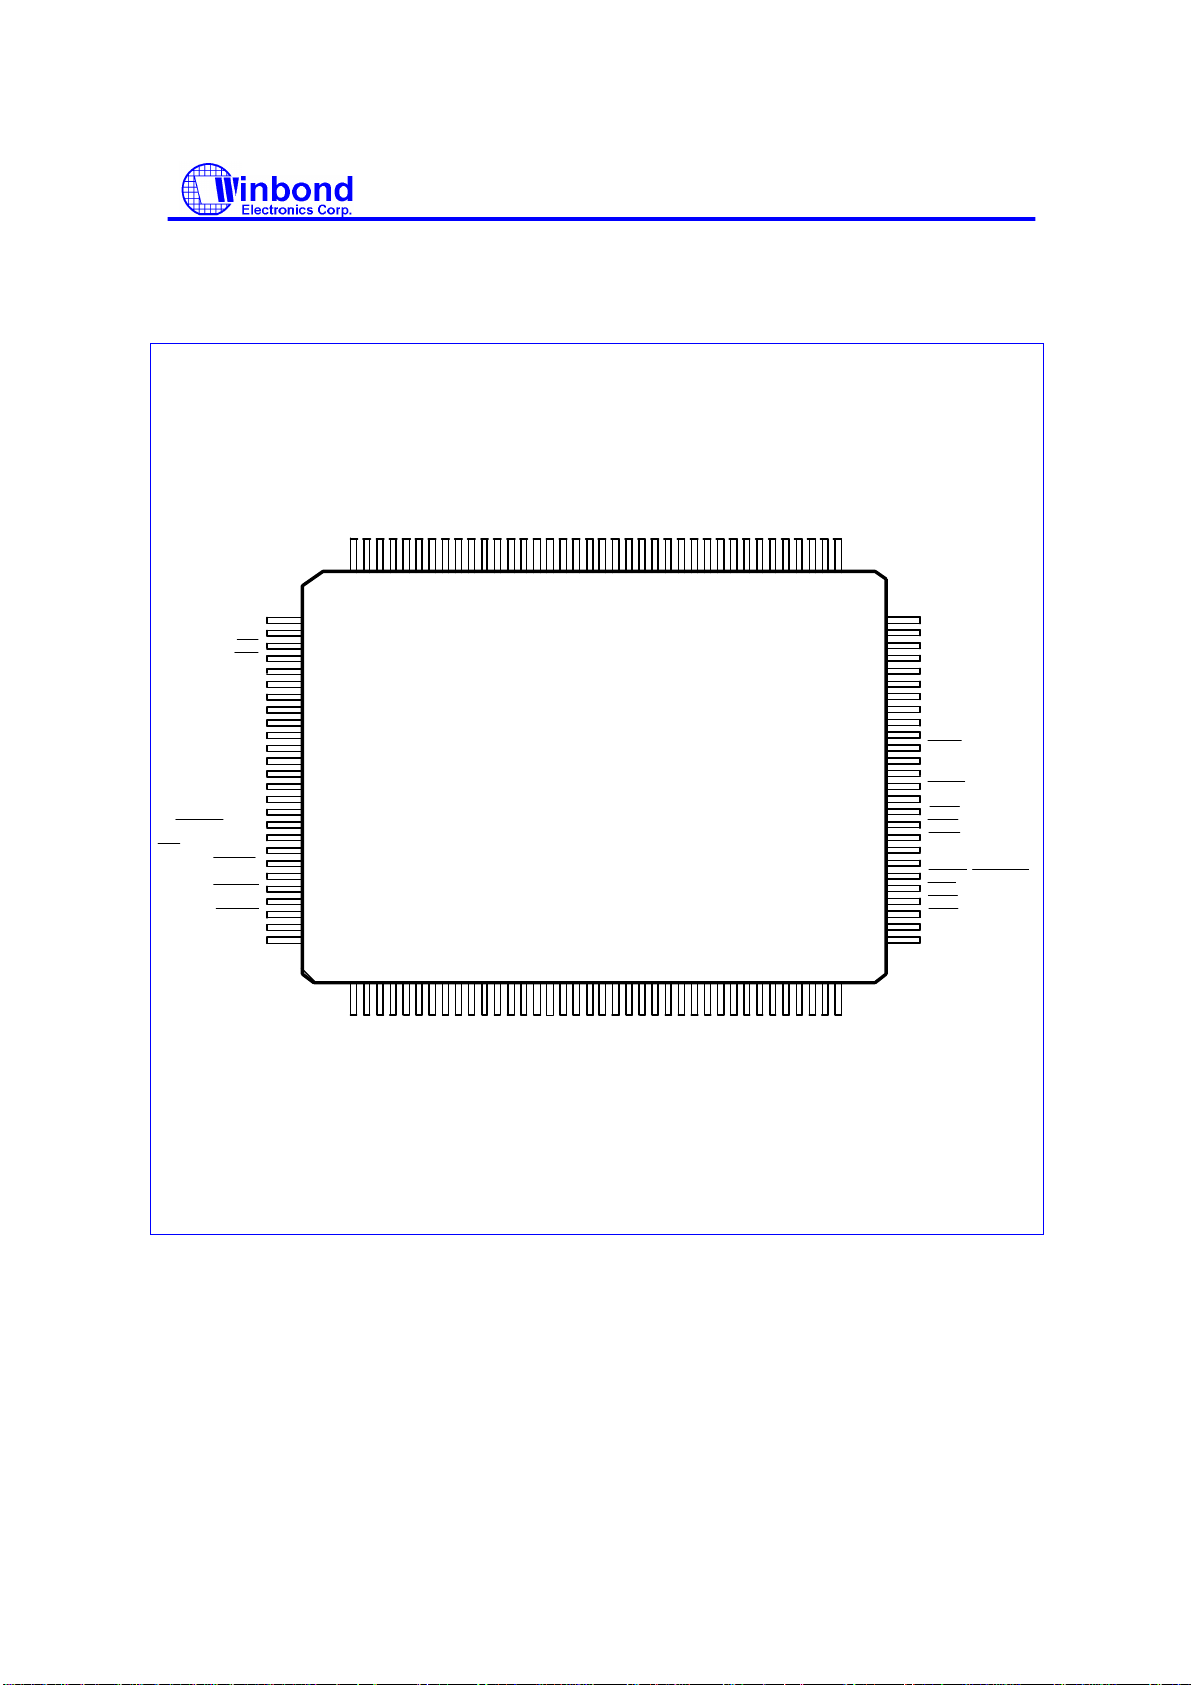
PIN CONFIGURATION
I
I
I
R
I
R
R
Q
R
Q
Q
1
Q
1
1
2
1
0
1
1
1
1
9
0
0
0
9
2
1
IRQ14/GP14
IRQ15/GP15
IOR
IOW
AEN
IOCHRDY
D0
D1
D2
D3
VCC
D7
DACK0/GP16
SCI/DRQ0/GP17
VSS
DACK1
DRQ1
DACK2
DRQ2
DACK3
DRQ3
TC
D4
D5
D6
MR
103
104
105
106
107
108
109
110
111
112
113
114
115
116
117
118
119
120
121
122
123
124
125
126
127
128
0
1 2 345
I
R
Q
3
989
I
R
Q
4
7
I
I
R
R
Q
Q
6
5
969
5949392
678 9
I
I
R
R
Q
Q
8
7
I
R
A
Q
1
9
5
9
1
1
0111213
A
A
V
1
1
S
3
4
S
9089888
1
415161718
PRELIMINARY
/
/
P
A
P
N
A
N
S
S
W
/
W
O
S
U
I
M
N
T
,
I
,
,
G
G
G
A
A
A
V
1
1
C
C
011
2
868
8
5
7
4
1
920
9
838
281807978
2
1
A
5
222
324252627
777
6
A1A2A3A4A6A7A8A
7
5
282
P
P
2
2
A
3
2
0
747
7
3
271
9303132
V
S
B
G
P
2
1
3
3
706
/
K
M
/
P
R
C
C
R
2
I
L
L
I
0
B
K
K
A
6
6
6
9
6
867
5
64
VBAT
63
XTAL1
62
VSS
61
XTAL2
MDATA
60
KDATA
59
KBLOCK/GP13
58
KBRST/GP12
57
56
GA20/GP11
VCC
55
54
DCDB
53
SOUTB/PEN48
52
SINB
51
DTRB
50
RTSB
49
DSRB
48
CTSB
47
DCDA
46
SOUTA/PENKBC
45
SINA
44
DTRA/PNPCSV
43
RTSA/HEFRAS
42
DSRA
41
CTSA
40
GP24
39
3
3
3
3
3
5
4
6
8
7
GP25
D
D
/
/
C
L
K
I
N
//
R
R
V
V
D
D
E
E
N
N
1
0
,
G
P
1
0
,
/
S
C
I
/
D
H
T
R
W
S
P
E
R
D
K
A
A
A
C
D
K
T
H
0
A
G
/
/
/
/
/
/
M
D
S
W
W
D
O
I
T
E
D
S
B
E
R
A
P
P
/
/
S
/
I
M
L
D
N
O
C
S
D
A
T
B
E
X
P
/
P
V
B
E
C
U
C
S
Y
P
V
D
D
A
D
S
7
C
6
S 5
K
P
P
/
P
P
P
D
D
S
D
D
D
0
1
L
2
3
4
I
N
I
/
I
N
I
T
I
/
/
/
R
A
E
R
S
T
F
T
R
R
X
D
B
R
X
Publication Release Date: April 1998
-4- Revision 0.62
Page 13
W83977TF
IOR
IOW
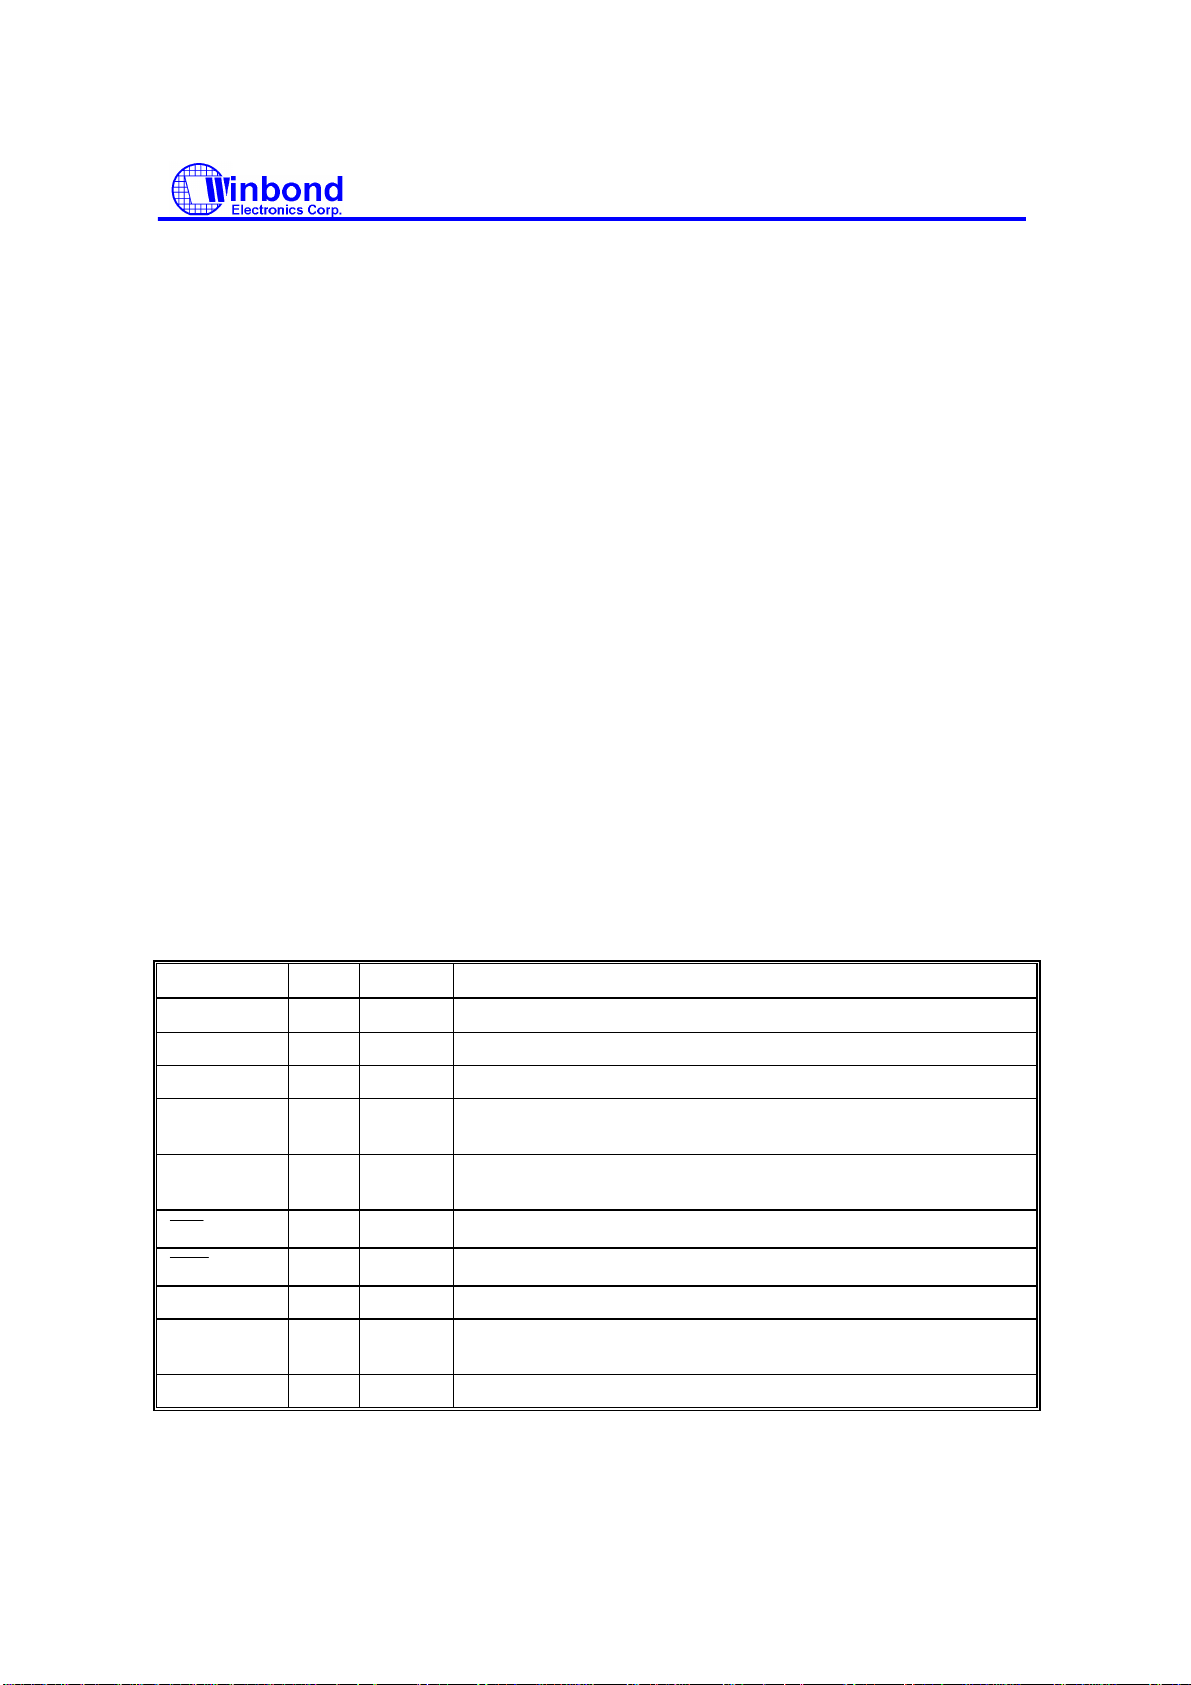
1. PIN DESCRIPTION
Note: Please refer to Section 11.2 DC CHARACTERISTICS for details.
I/O6t - TTL level bi-directional pin with 6 mA source-sink capability
I/O8t - TTL level bi-directional pin with 8 mA source-sink capability
I/O8 - CMOS level bi-directional pin with 8 mA source-sink capability
I/O
- TTL level bi-directional pin with 12 mA source-sink capability
12t
I/O12 - CMOS level bi-directional pin with 12 mA source-sink capability
I/O
- CMOS level bi-directional pin with 16 mA source-sink capability with internal pull-up resistor
16u
I/OD
- CMOS level bi-directional pin open drain output with 16 mA sink capability with internal pull-up resistor
16u
I/O
- TTL level bi-directional pin with 24 mA source-sink capability
24t
OUT8t - TTL level output pin with 8 mA source-sink capability
OUT
- TTL level output pin with 12 mA source-sink capability
12t
OD12 - Open-drain output pin with 12 mA sink capability
OD24 - Open-drain output pin with 24 mA sink capability
INt - TTL level input pin
INc - CMOS level input pin
INcu - CMOS level input pin with internal pull-up resitor
INcs - CMOS level Schmitt-triggered input pin
INts - TTL level Schmitt-triggered input pin
IN
- TTL level Schmitt-triggered input pin with internal pull-up resistor
tsu
PRELIMINARY
1.1 Host Interface
SYMBOL PIN I/O FUNCTION
I/O
I/O
IN
IN
System address bus bits 0-10
t
System address bus bits 11-14
t
System address bus bit 15
t
System data bus bits 0-5
12t
System data bus bits 6-7
12t
CPU I/O read signal
ts
CPU I/O write signal
ts
System address bus enable
ts
In EPP Mode, this pin is the IO Channel Ready output to extend
24
the host read/write cycle.
Master Reset; Active high; MR is low during normal operations.
ts
Publication Release Date: April 1998
A0−A10
A11-A14 86-89
A15 91 IN
D0−D5
74-84
109-
114
D6−D7
116-
117
105 IN
106 IN
AEN 107 IN
IOCHRDY 108 OD
MR 118 IN
-5 - Revision 0.62
Page 14
W83977TF
DACK0
SCI
DACK1
DACK2
DACK3
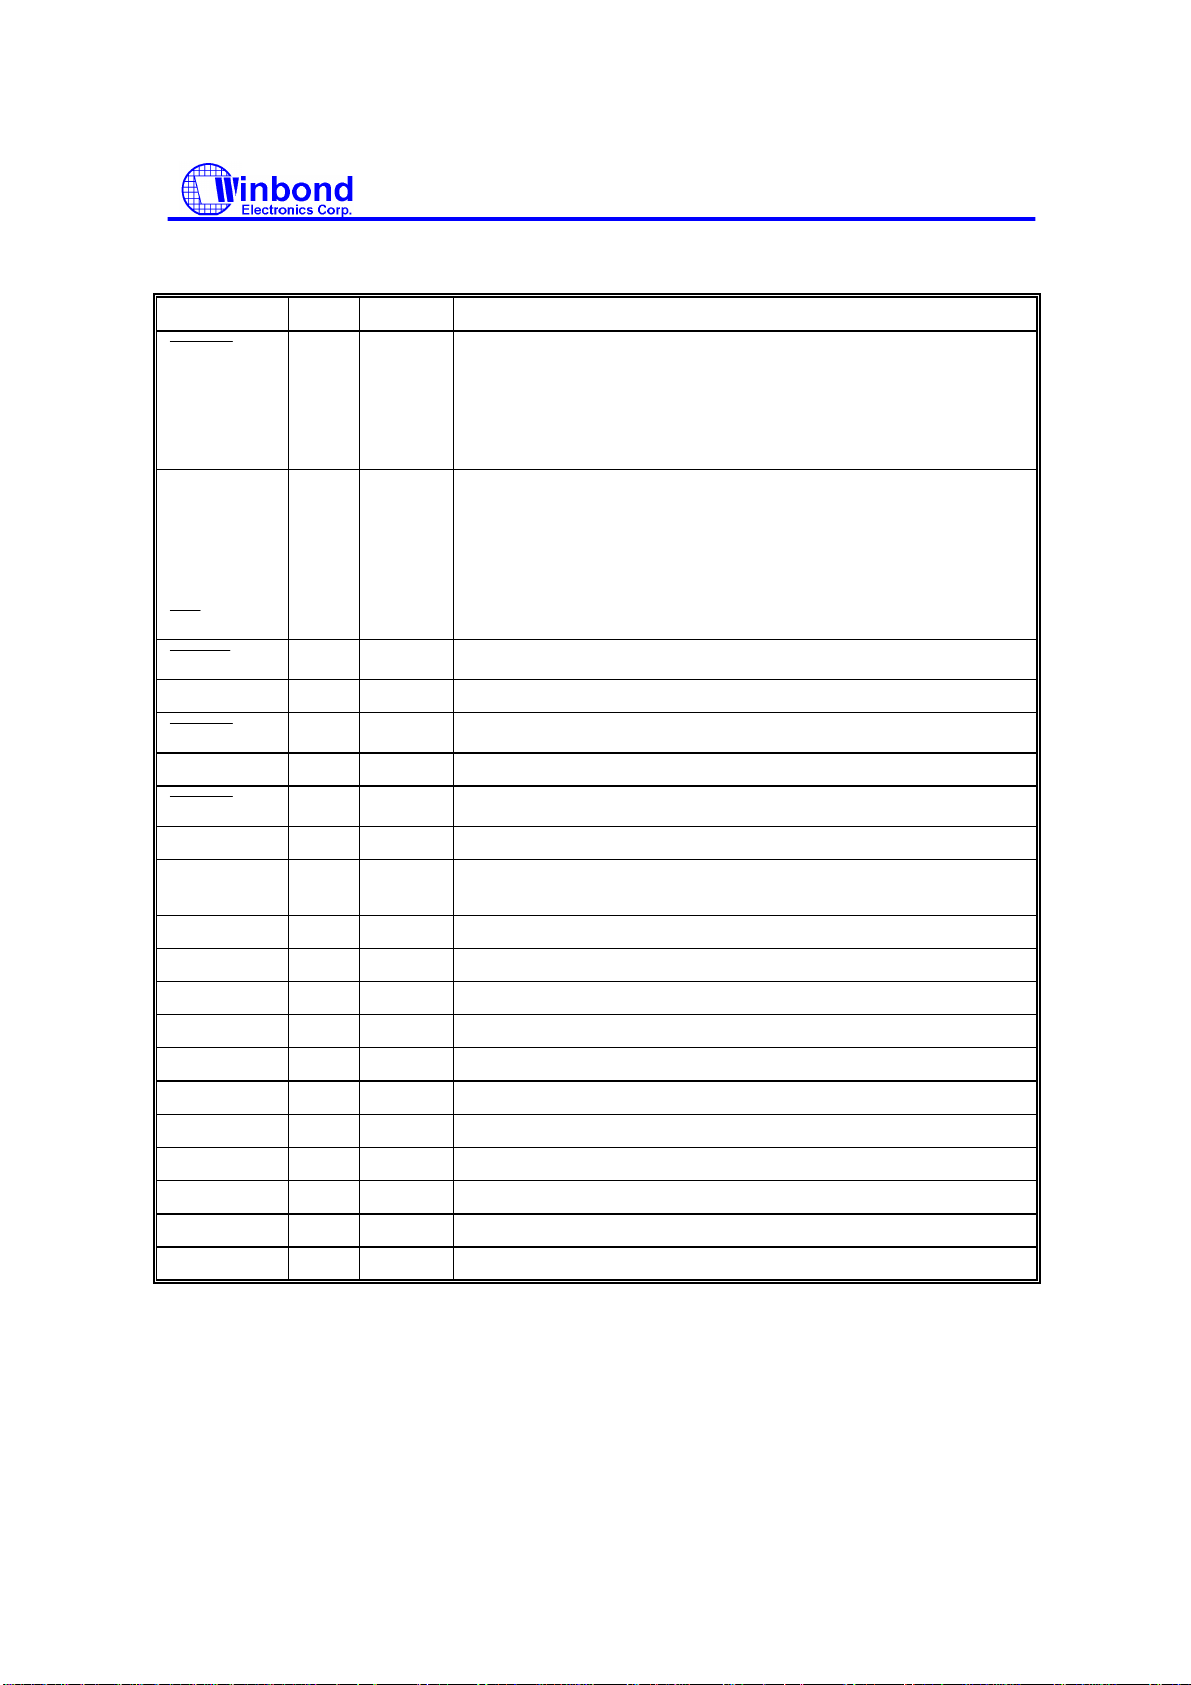
1.1 Host Interface, continued
SYMBOL PIN I/O FUNCTION
I/O
OUT
DMA Channel 0 Acknowledge signal. (CR2C bit 5_4 = 00, default)
tsu
General purpose I/O port 1bit 6. (CR2C bit 5_4 = 01)
12t
Alternate function from GP16: Watch dog timer output
KBC P15 I/O port. (CR2C bit 5_4 = 10)
12t
DMA Channel 0 request signal. (CR2C bit 7_6 = 00, default)
12t
General purpose I/O port 1bit 7. (CR2C bit 7_6 = 01)
12t
Alternate Function from GP17: Power LED output.
KBC P14 I/O port (CR2C bit 7_6 = 10)
12t
System Control Interrupt (CR2C bit 7_6 = 11)
12t
DMA Channel 1 Acknowledge signal
ts
DMA Channel 1 request signal
12t
DMA Channel 2 Acknowledge signal
ts
DMA Channel 2 request signal
12t
DMA Channel 3 Acknowledge signal
ts
DMA Channel 3 request signal
12t
Terminal Count. When active, this pin indicates termination of a
ts
119 IN
I/O
I/O
121 OUT
I/O
122 IN
GP16
(WDTO)
P15
DRQ0
GP17
(PLEDO)
P14
DRQ1 123 OUT
124 IN
DRQ2 125 OUT
126 IN
DRQ3 127 OUT
TC 128 IN
DMA transfer.
IRQ1 99 OUT
IRQ3 98 OUT
IRQ4 97 OUT
IRQ5 96 OUT
IRQ6 95 OUT
IRQ7 94 OUT
IRQ8 93 OUT
IRQ9 92 OUT
IRQ10 100 OUT
IRQ11 101 OUT
IRQ12 102 OUT
Interrupt request 1
12t
Interrupt request 3
12t
Interrupt request 4
12t
Interrupt request 5
12t
Interrupt request 6
12t
Interrupt request 7
12t
Interrupt request 8
12t
Interrupt request 9
12t
Interrupt request 10
12t
Interrupt request 11
12t
Interrupt request 12
12t
PRELIMINARY
Publication Release Date: April 1998
-6- Revision 0.62
Page 15
W83977TF
GPACS
GPAWE
SMI
SMI
SCI
PANSWOUT
PANSWIN
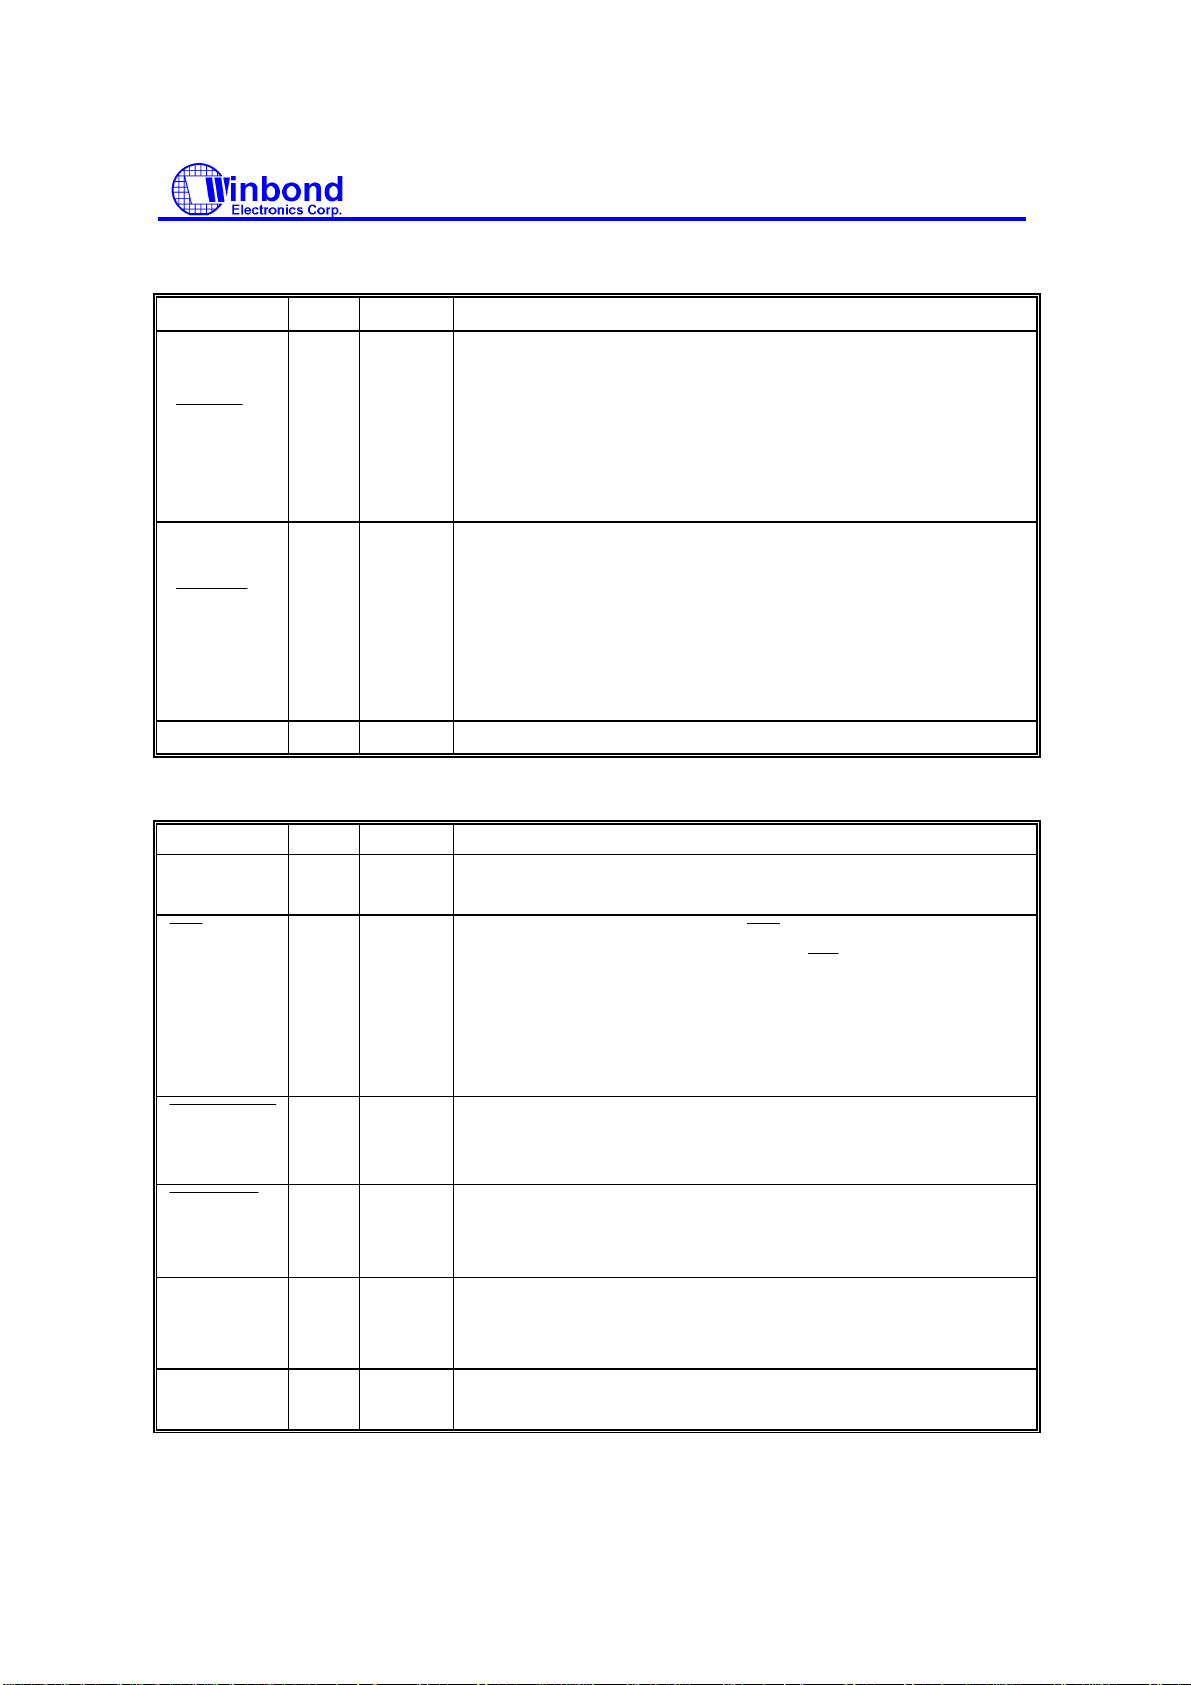
1.1 Host Interface, continued
SYMBOL PIN I/O FUNCTION
IRQ14 103 OUT
GP14 I/O
(
)
Alternate Function 1 from GP14: General purpose address
Interrupt request 14. (CR2C bit 1_0 = 00, default)
12t
General purpose I/O port 1 bit 4. (CR2C bit 1_0 = 01)
12t
decode output.
(P17)
PLEDO OUT
IRQ15
GP15
(
)
(P12)
WDT
CLKIN 1 IN
Alternate Function 2 from GP14: KBC P17 I/O port.
Power LED output. (CR2C bit 1_0 = 10)
12t
104 OUT
I/O
Interrupt request 15.(CR2C bit 3_2 = 00, default)
12t
General purpose I/O port 1 bit 5. (CR2C bit 3_2 = 01)
12t
Alternate Function 1 from GP15: General purpose address write
enable output.
Alternate Function 2 from GP15: KBC P12 I/O port.
OUT
Watch-Dog timer output. (CR2C bit 3_2 = 10)
12t
24 or 48 MHz clock input, selectable through bit 5 of CR24.
t
1.2 General Purpose I/O Port
SYMBOL PIN I/O FUNCTION
GP20
(KBRST)
GP21
69 I/O
70 OUT
I/O
(P13) Alternate Function from GP21: KBC P13 I/O port.
P16
I/O
72 OUT
GP22
(P14)
GP23
(P15)
Alternate Function from GP22: KBC P14 I/O port.
73 IN
Alternate Function from GP23: KBC P15 I/O port
GP24 40 I/O
(P16) Alternate Function from GP24: KBC P16 I/O port
P13
GP25
(GA20)
39 I/O
Alternate Function from GP25: GATE A20 (KBC P21)
I/O
I/O
I/O
General purpose I/O port 2 bit 0.
12t
Alternate Function from GP20: Keyboard reset (KBC P20)
12t
For the power management, the
is active low by the power
management events, that generate and
(CR2B bit 4_3 = 00, default)
General purpose I/O port 2 bit 1. (CR2B bit 4_3 = 01)
12t
KBC P16 I/O port. (CR2B bit 4_3 = 10)
12t
Panel Switch output. (CR2B bit 5 = 0, default)
12t
General purpose I/O port 2 bit 2. (CR2B bit 5 = 1)
12t
Panel Switch input. (CR2B bit 7_6 = 00, default)
12t
General purpose I/O port 2 bit 3. (CR2B bit 7_6 = 01)
12t
General purpose I/O port 2 bit 4 (CR2A bit 5_4 = 01)
12t
KBC P13 I/O port. (CR2A bit 5_4 = 10)
12t
General purpose I/O port 2 bit 5.
12
in ACPI mode.
PRELIMINARY
Publication Release Date: April 1998
-7 - Revision 0.62
Page 16
W83977TF
CTSA
CTSB
DSRA
DSRB
RTSA
RTSB
DTRA
PNPCSV
PNPCSV
PNPCSV
DTRB
DCDA
DCDB
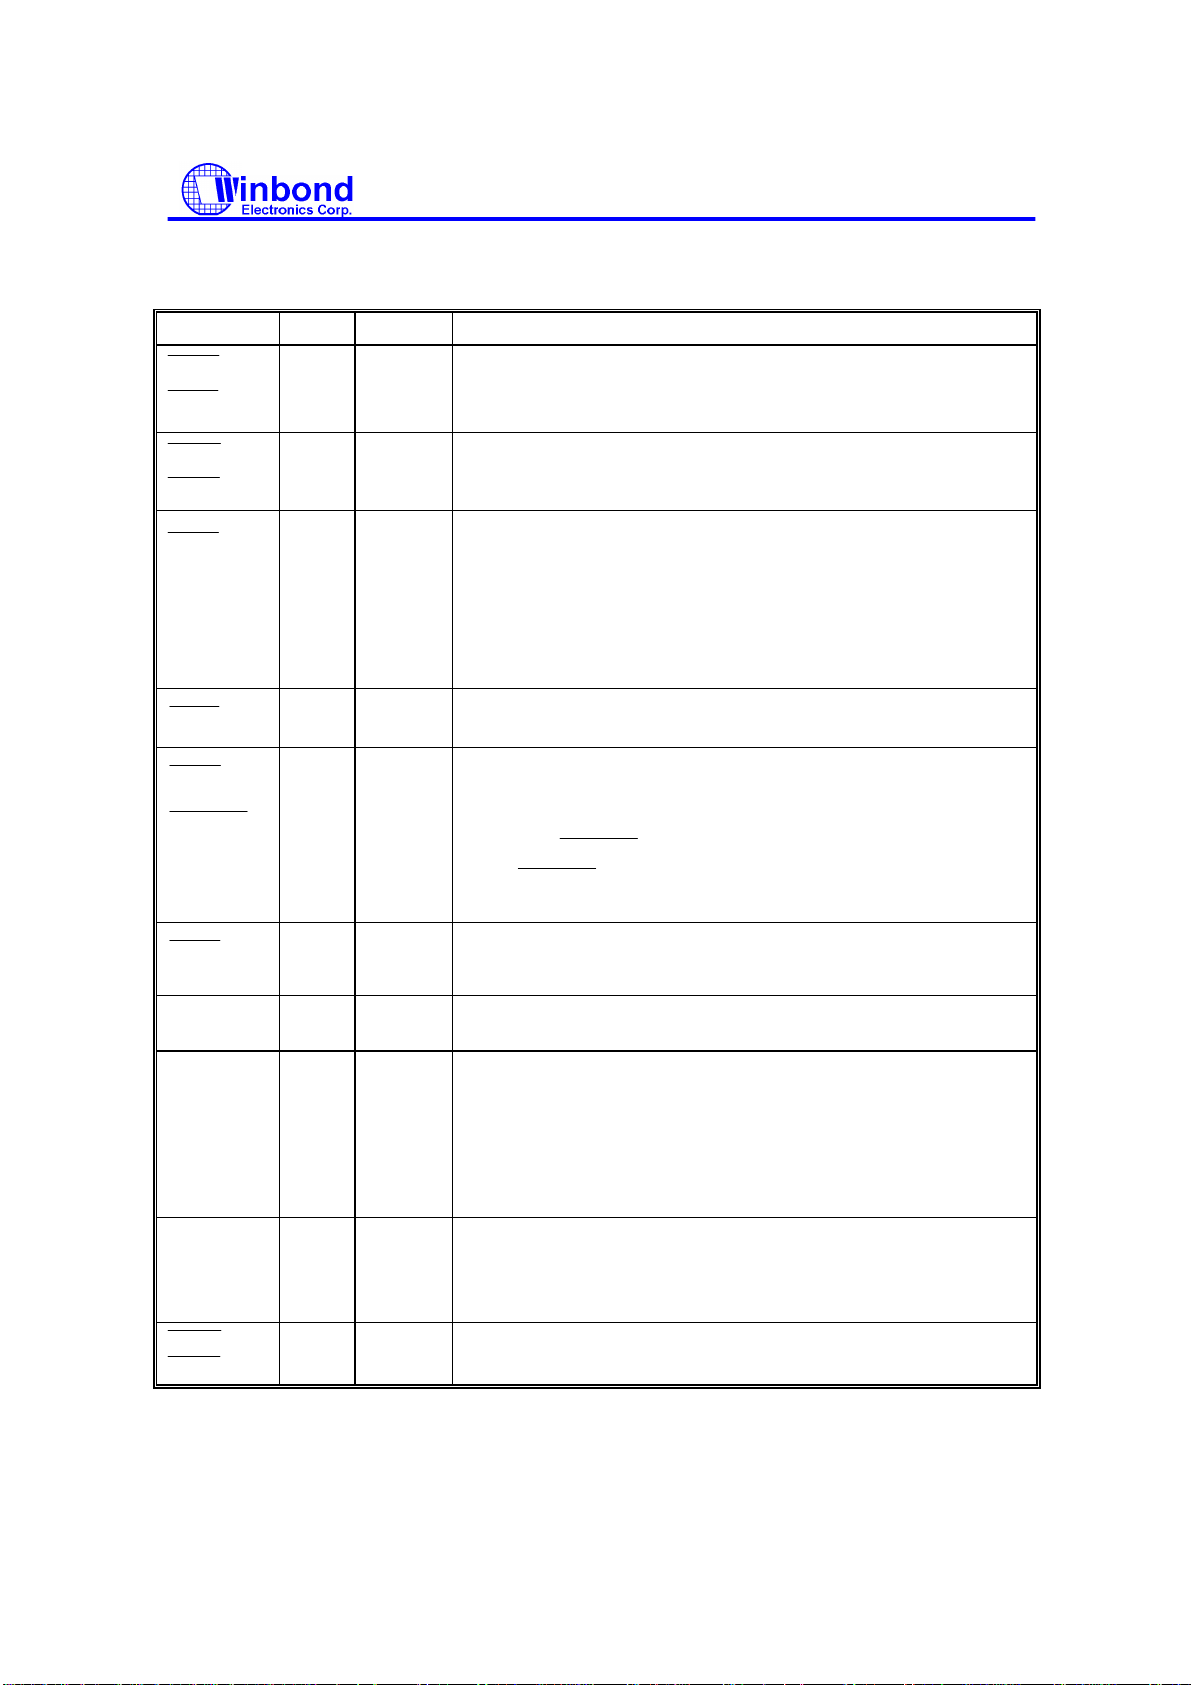
1.3 Serial Port Interface
SYMBOL PIN I/O FUNCTION
HEFRAS
41
48
42
49
43
During power-on reset, this pin is pulled down internally and is
50
44
IN
IN
I/O
I/O
I/O
Clear To Send is the modem control input.
t
The function of these pins can be tested by reading Bit 4 of the
handshake status register.
Data Set Ready. An active low signal indicates the modem or data
t
set is ready to establish a communication link and transfer data to
the UART.
UART A Request To Send. An active low signal informs the
8t
modem or data set that the controller is ready to send data.
defined as HEFRAS, which provides the power-on value for CR26
bit 6 (HEFRAS). A 4.7 kΩ is recommended if intends to pull up.
(select 370H as configuration I/O port′s address)
UART B Request To Send. An active low signal informs the
8t
modem or data set that the controller is ready to send data.
UART A Data Terminal Ready. An active low signal informs the
8t
modem or data set that the controller is ready to communicate.
During power-on reset, this pin is pulled down internally and is
defined as
bit 0 (
, which provides the power-on value for CR24
). A 4.7 kΩ is recommended if intends to pull up.
(clear the default value of FDC, UARTs, and PRT)
PRELIMINARY
51
SINA
SINB
SOUTA
45, 52
46
PENKBC
I/O
IN
I/O
UART B Data Terminal Ready. An active low signal informs the
8t
modem or data set that controller is ready to communicate.
Serial Input. Used to receive serial data through the
t
communication link.
UART A Serial Output. Used to transmit serial data out to the
8t
communication link.
During power-on reset, this pin is pulled down internally and is
defined as PENKBC, which provides the power-on value for CR24
bit 2 (ENKBC). A 4.7 kΩ resistor is recommended if intends to pull
up. (enable KBC)
SOUTB
PEN48
53
I/O
UART B Serial Output. During power-on reset, this pin is pulled
8t
down internally and is defined as PEN48, which provides the
power-on value for CR24 bit 6 (EN48). A 4.7 kΩ resistor is
recommended if intends to pull up.
47
54
IN
Data Carrier Detect. An active low signal indicates the modem or
t
data set has detected a data carrier.
Publication Release Date: April 1998
-8- Revision 0.62
Page 17
W83977TF
RIA RIB
WE2
WE2
WD2
WD
WD2
PRELIMINARY
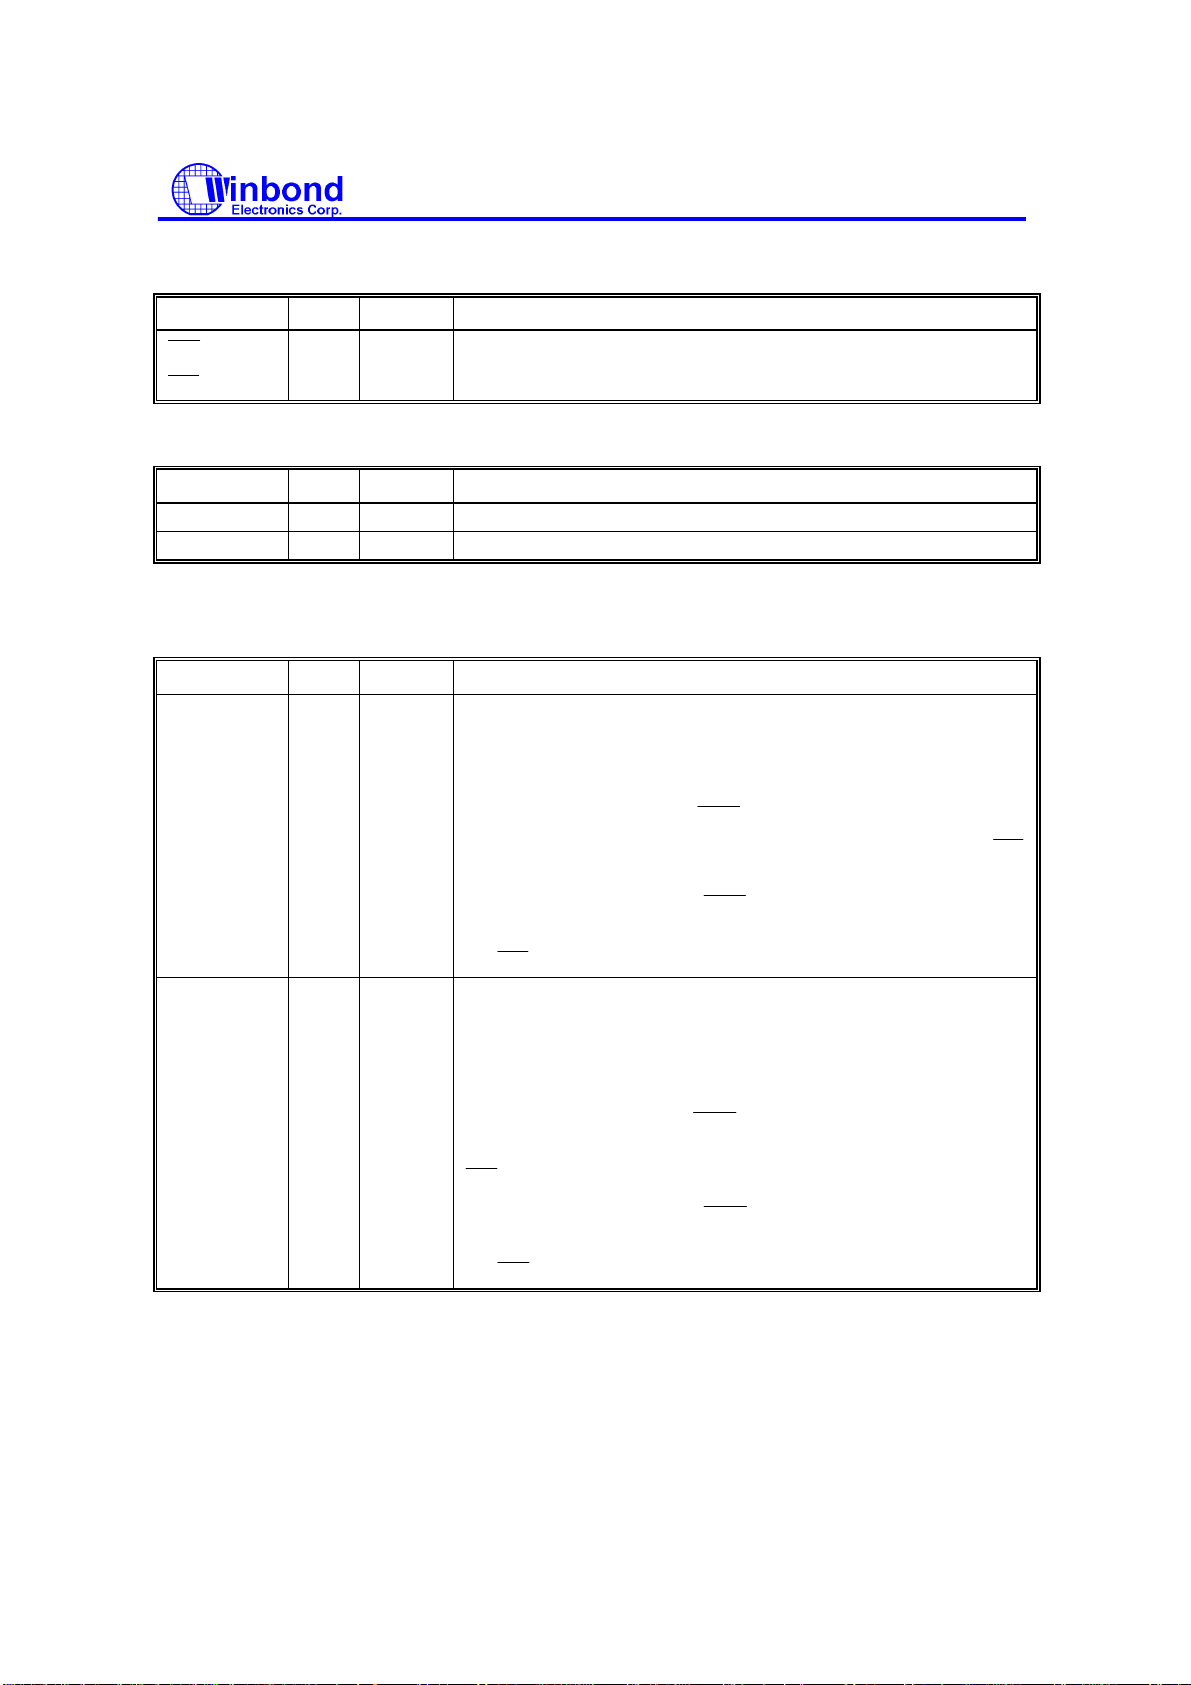
1.3 Serial Port Interface, continued
SYMBOL PIN I/O FUNCTION
65
66
IN
Ring Indicator. An active low signal indicates that a ring signal is
t
being received from the modem or data set.
1.4 Infrared Interface
SYMBOL PIN I/O FUNCTION
IRRX 37 IN
IRTX 38 OUT
Infrared Receiver input.
cs
Infrared Transmitter Output.
12t
1.5 Multi-Mode Parallel Port
The following pins have alternate functions, which are controlled by CR28 and L3-CRF0.
SYMBOL PIN I/O FUNCTION
PRINTER MODE: SLCT
SLCT 18 IN
OD
OD
PE
19 IN
OD
OD
t
An active high input on this pin indicates that the printer is selected.
This pin is pulled high internally. Refer to description of the
parallel port for definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE:
12
This pin is for Extension FDD B; its function is the same as the WE
pin of FDC.
EXTENSION 2FDD MODE:
12
This pin is for Extension FDD A and B; it function is the same as
the WE pin of FDC.
PRINTER MODE: PE
t
An active high input on this pin indicates that the printer has
detected the end of the paper. This pin is pulled high internally.
Refer to description of the parallel port for definition of this pin in
ECP and EPP mode.
12
EXTENSION FDD MODE:
This pin is for Extension FDD B; its function is the same as the
12
pin of FDC.
EXTENSION 2FDD MODE:
This pin is for Extension FDD A and B; its function is the same as
the WD pin of FDC.
Publication Release Date: April 1998
-9 - Revision 0.62
Page 18
W83977TF
MOB2
MOB
MOB2
MOB
ACK
ACK
DSB2
DSB
DSB2
DSB
ERR
ERR
HEAD
2
HEAD
HEAD
2
HEAD
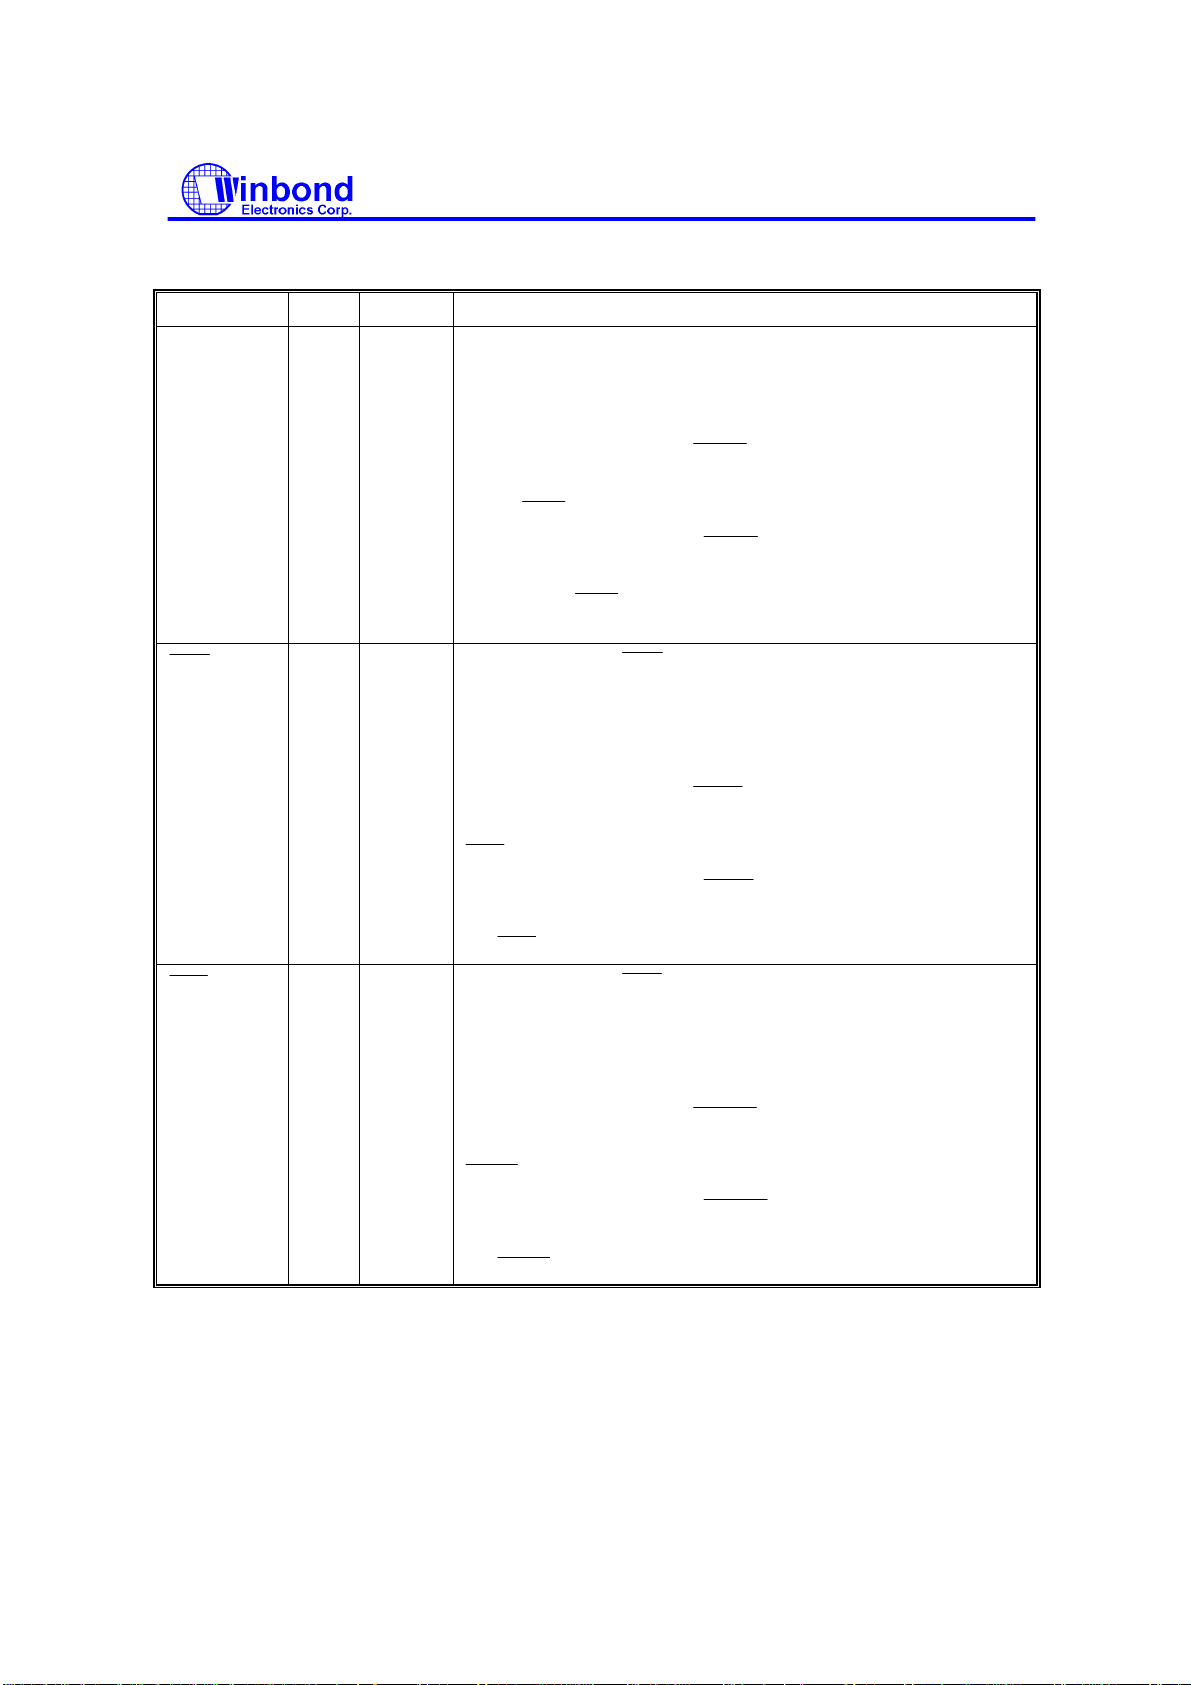
1.5 Multi-Mode Parallel Port, continued
SYMBOL PIN I/O FUNCTION
BUSY
21 IN
22 IN
34
PRINTER MODE: BUSY
t
OD
OD
OD
OD
IN
OD
OD
An active high input indicates that the printer is not ready to receive
data. This pin is pulled high internally. Refer to description of the
parallel port for definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE:
12
This pin is for Extension FDD B; the function of this pin is the same
as the
12
EXTENSION 2FDD MODE:
pin of FDC.
This pin is for Extension FDD A and B; the function of this pin is the
same as the
t
PRINTER MODE:
pin of FDC.
An active low input on this pin indicates that the printer has
received data and is ready to accept more data. This pin is pulled
high internally. Refer to description of the parallel port for
definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE:
12
This pin is for the Extension FDD B; its functions is the same as the
pin of FDC.
EXTENSION 2FDD MODE:
12
This pin is for Extension FDD A and B; it functions is the same as
the
t
PRINTER MODE:
pin of FDC.
An active low input on this pin indicates that the printer has
encountered an error condition. This pin is pulled high internally.
Refer to description of the parallel port for definition of this pin in
ECP and EPP mode.
EXTENSION FDD MODE:
12
This pin is for Extension FDD B; its function is the same as the
12
pin of FDC.
EXTENSION 2FDD MODE:
This pin is for Extension FDD A and B; its function is the same as
the
pin of FDC.
PRELIMINARY
Publication Release Date: April 1998
-10- Revision 0.62
Page 19
W83977TF
SLIN
SLIN
STEP
2
STEP
STEP
2
STEP
INIT
INIT
DIR2
DIR
DIR2
DIR
AFD
AFD
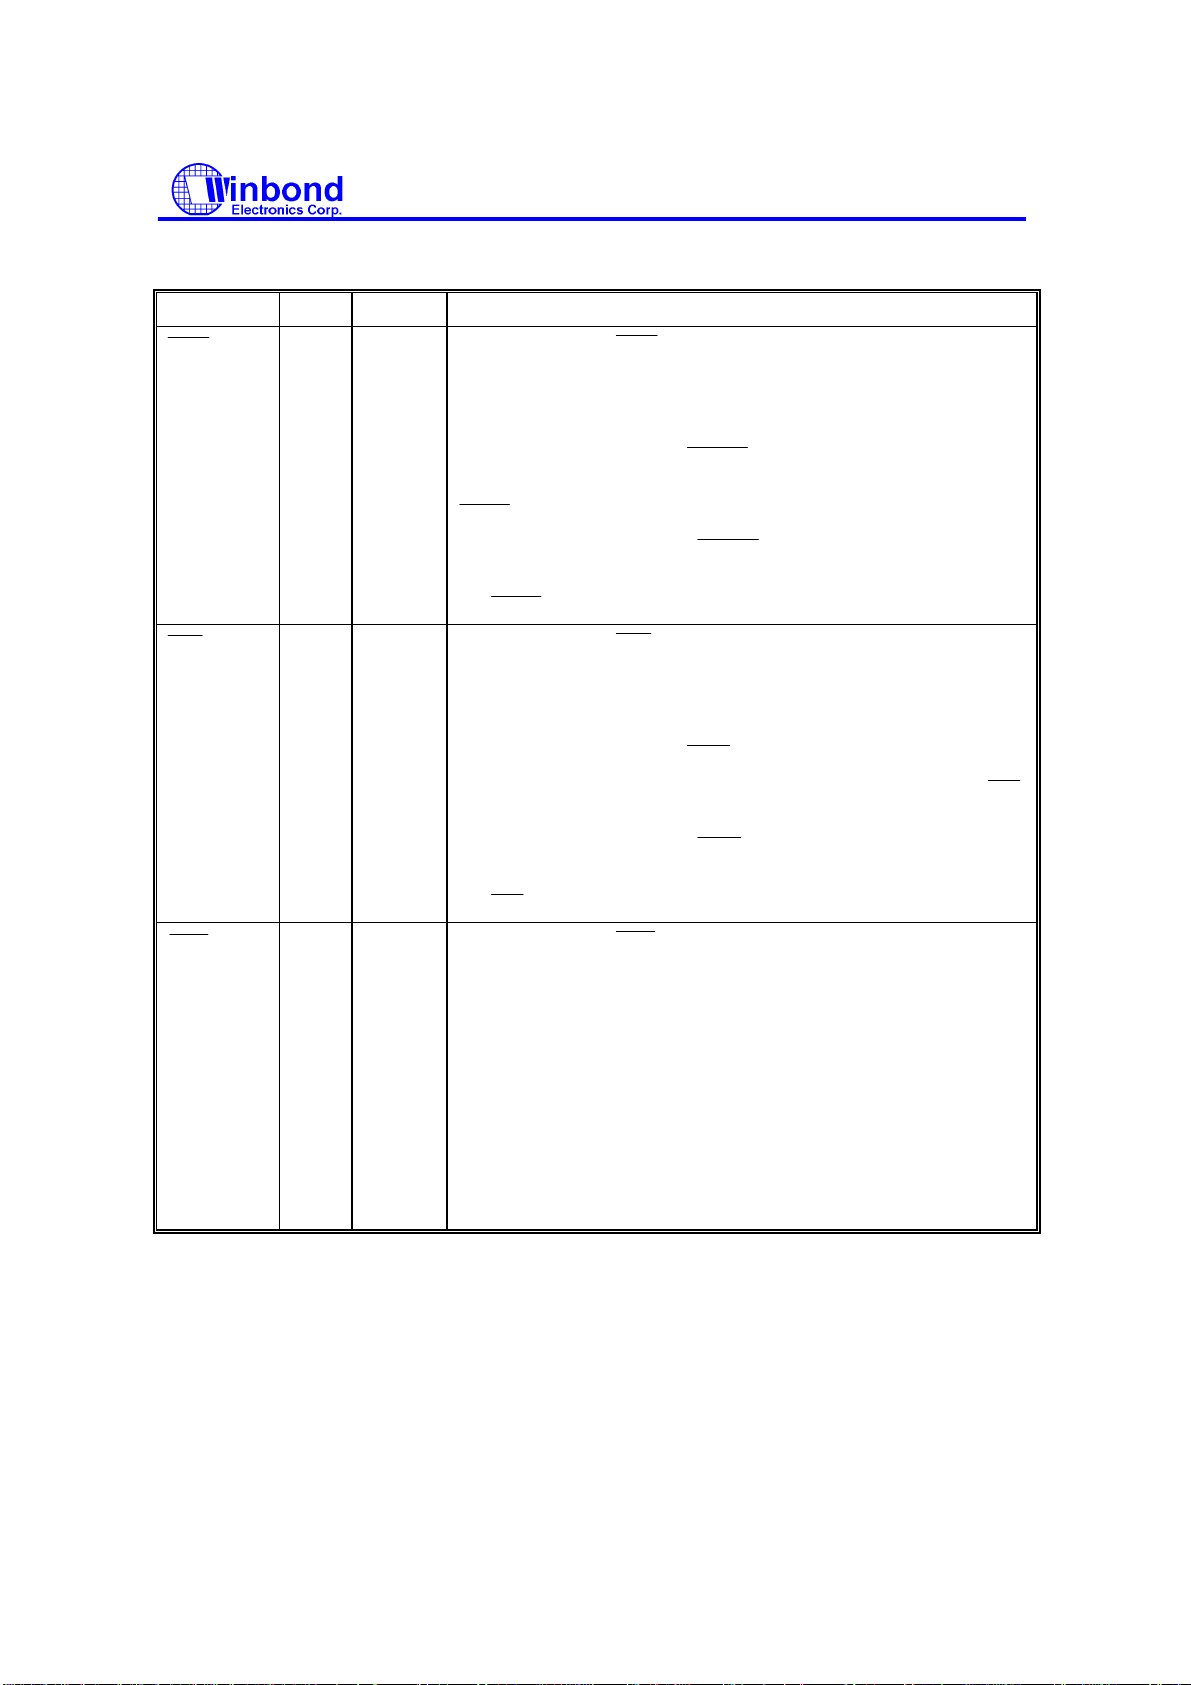
1.5 Multi-Mode Parallel Port, continued
SYMBOL PIN I/O FUNCTION
32 OD
33 OD
35 OD
12
PRINTER MODE:
Output line for detection of printer selection. This pin is pulled high
OD
OD
OD
OD
OD
OD
internally. Refer to description of the parallel port for definition of
this pin in ECP and EPP mode.
EXTENSION FDD MODE:
12
This pin is for Extension FDD B; its function is the same as the
pin of FDC.
EXTENSION 2FDD MODE:
12
This pin is for Extension FDD A and B; its function is the same as
the
12
PRINTER MODE:
pin of FDC.
Output line for the printer initialization. This pin is pulled high
internally. Refer to description of the parallel port for definition of
this pin in ECP and EPP mode.
EXTENSION FDD MODE:
12
This pin is for Extension FDD B; its function is the same as the
pin of FDC.
EXTENSION 2FDD MODE:
12
This pin is for Extension FDD A and B; its function is the same as
the
12
PRINTER MODE:
pin of FDC.
An active low output from this pin causes the printer to auto feed a
line after a line is printed. This pin is pulled high internally. Refer
to description of the parallel port for definition of this pin in ECP and
EPP mode.
EXTENSION FDD MODE: DRVDEN0
12
This pin is for Extension FDD B; its function is the same as the
DRVDEN0 pin of FDC.
EXTENSION 2FDD MODE: DRVDEN0
12
This pin is for Extension FDD A and B; its function is the same as
the DRVDEN0 pin of FDC.
PRELIMINARY
Publication Release Date: April 1998
-11 - Revision 0.62
Page 20
W83977TF
STB
STB
INDEX
2
INDEX
INDEX
2
INDEX
TRAK
02
TRAK
0
TRAK
02
TRAK
0
WP2
WP2
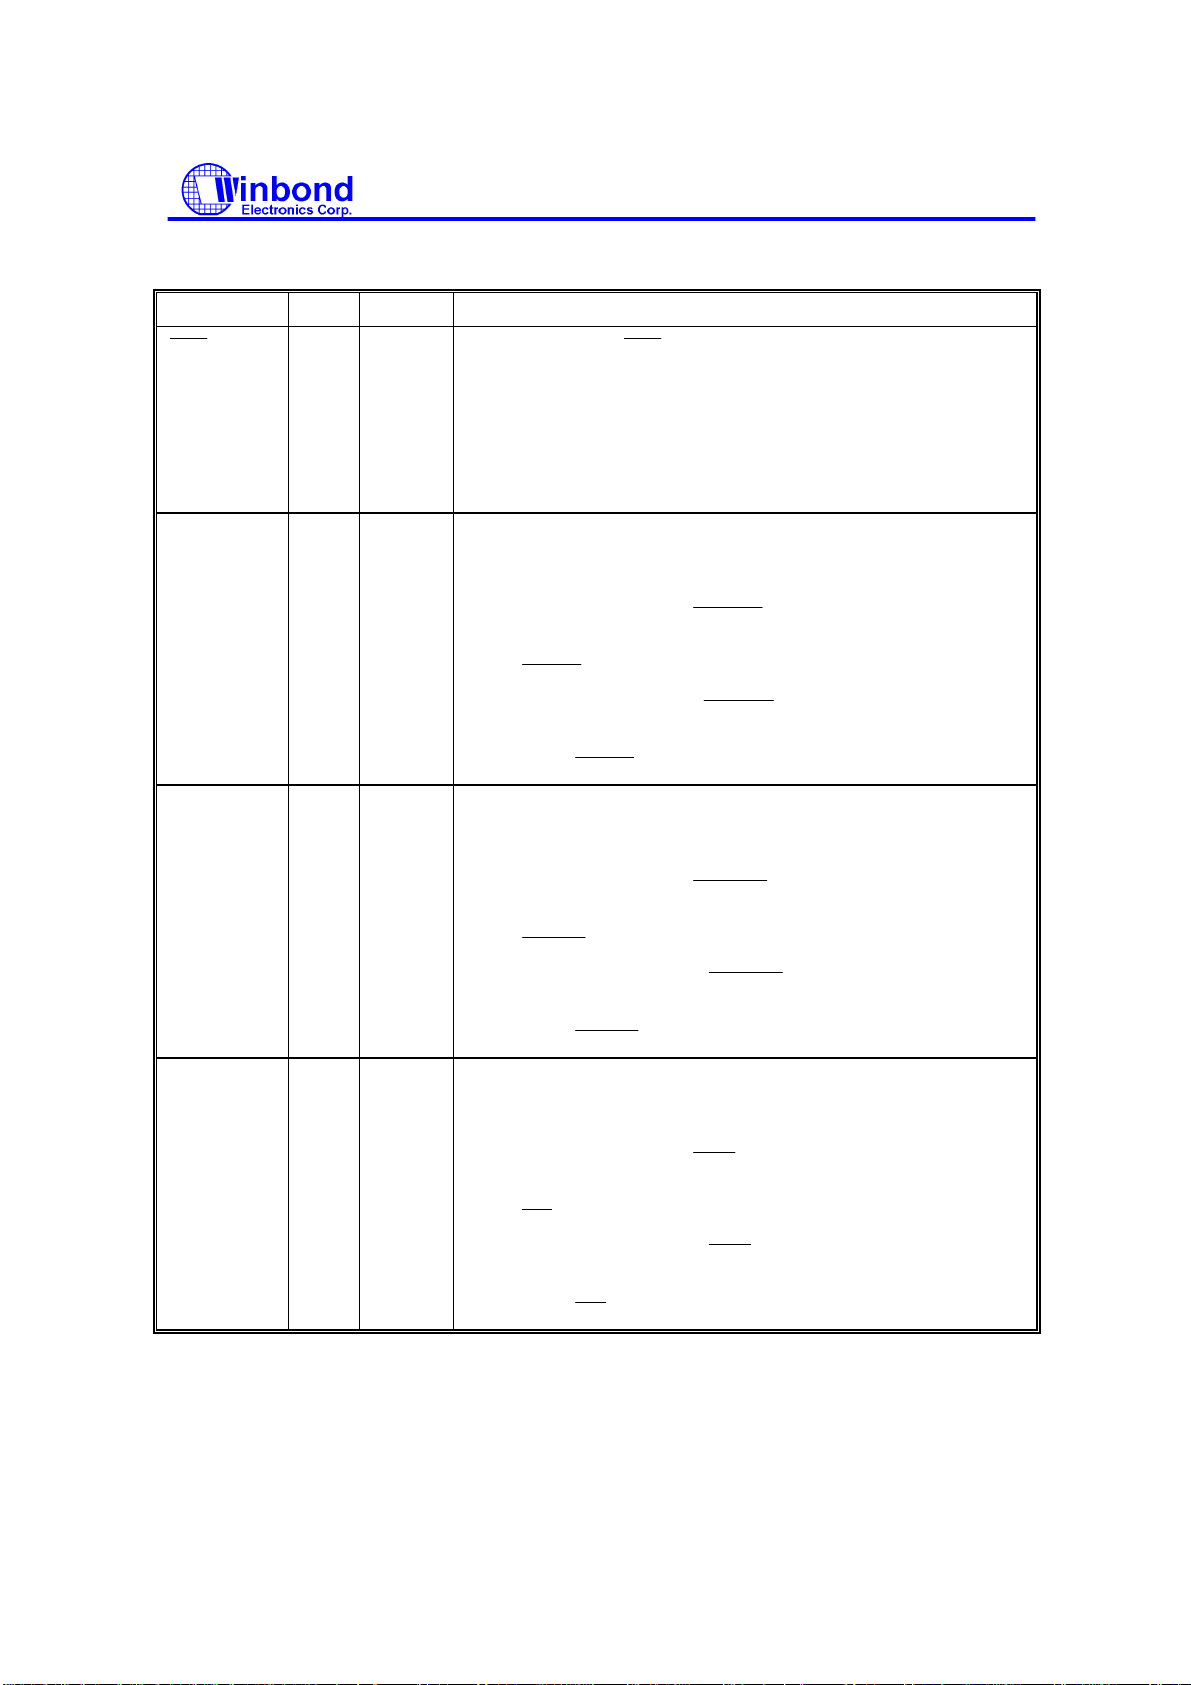
1.5 Multi-Mode Parallel Port, continued
SYMBOL PIN I/O FUNCTION
36 OD
12
PRINTER MODE:
An active low output is used to latch the parallel data into the
printer. This pin is pulled high internally. Refer to description of the
parallel port for definition of this pin in ECP and EPP mode.
PD0
31 I/O
- EXTENSION FDD MODE: This pin is a tri-state output.
- EXTENSION 2FDD MODE: This pin is a tri-state output.
PRINTER MODE: PD0
24t
Parallel port data bus bit 0. Refer to description of the parallel port
for definition of this pin in ECP and EPP mode.
IN
IN
t
EXTENSION FDD MODE:
This pin is for Extension FDD B; the function of this pin is the same
as the
t
EXTENSION 2FDD MODE:
pin of FDC. It is pulled high internally.
This pin is for Extension FDD A and B; the function of this pin is the
PD1
same as the
30 I/O
PRINTER MODE: PD1
24t
IN
IN
Parallel port data bus bit 1. Refer to description of the parallel port
for definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE:
t
This pin is for Extension FDD B; the function of this pin is the same
as the
EXTENSION. 2FDD MODE:
t
pin of FDC. It is pulled high internally.
pin of FDC. It is pulled high internally.
This pin is for Extension FDD A and B; the function of this pin is the
PD2
same as the
29 I/O
PRINTER MODE: PD2
24t
IN
IN
Parallel port data bus bit 2. Refer to description of the parallel port
for definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE:
t
This pin is for Extension FDD B; the function of this pin is the same
as the WP pin of FDC. It is pulled high internally.
EXTENSION. 2FDD MODE:
t
pin of FDC. It is pulled high internally.
This pin is for Extension FDD A and B; the function of this pin is the
same as the WP pin of FDC. It is pulled high internally.
PRELIMINARY
Publication Release Date: April 1998
-12- Revision 0.62
Page 21

W83977TF
RDATA
2
RDATA
RDATA
2
RDATA
DSKCHG
2
DSKCHG
DSKCHG
2
DSKCHG
MOA2
MOA
1.5 Multi-Mode Parallel Port, continued
SYMBOL PIN I/O FUNCTION
PD3
28 I/O
IN
IN
24t
PRINTER MODE: PD3
Parallel port data bus bit 3. Refer to description of the parallel port
for definition of this pin in ECP and EPP mode.
t
EXTENSION FDD MODE:
This pin is for Extension FDD B; the function of this pin is the same
as the
t
EXTENSION 2FDD MODE:
pin of FDC. It is pulled high internally.
This pin is for Extension FDD A and B; this function of this pin is the
PD4
same as the
27 I/O
IN
IN
24t
PRINTER MODE: PD4
Parallel port data bus bit 4. Refer to description of the parallel port
for definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE:
t
This pin is for Extension FDD B; the function of this pin is the same
as the
EXTENSION 2FDD MODE:
t
pin of FDC. It is pulled high internally.
pin of FDC. It is pulled high internally.
This pin is for Extension FDD A and B; this function of this pin is the
PD5
PD6
same as the
26 I/O
24 I/O
OD
-
-
-
PRINTER MODE: PD5
24t
Parallel port data bus bit 5. Refer to description of the parallel port
for definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE: This pin is a tri-state output.
EXTENSION 2FDD MODE: This pin is a tri-state output.
PRINTER MODE: PD6
24t
Parallel port data bus bit 6. Refer to description of the parallel port
for definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE: This pin is a tri-state output.
EXTENSION. 2FDD MODE:
24
This pin is for Extension FDD A; its function is the same as the
pin of FDC. It is pulled high internally.
pin of FDC.
PRELIMINARY
Publication Release Date: April 1998
-13 - Revision 0.62
Page 22
W83977TF
DSA2
DSA
SCI
HEAD
WE
WD
STEP
DIR
MOB
DSA
DSB
1.5 Multi-Mode Parallel Port, continued
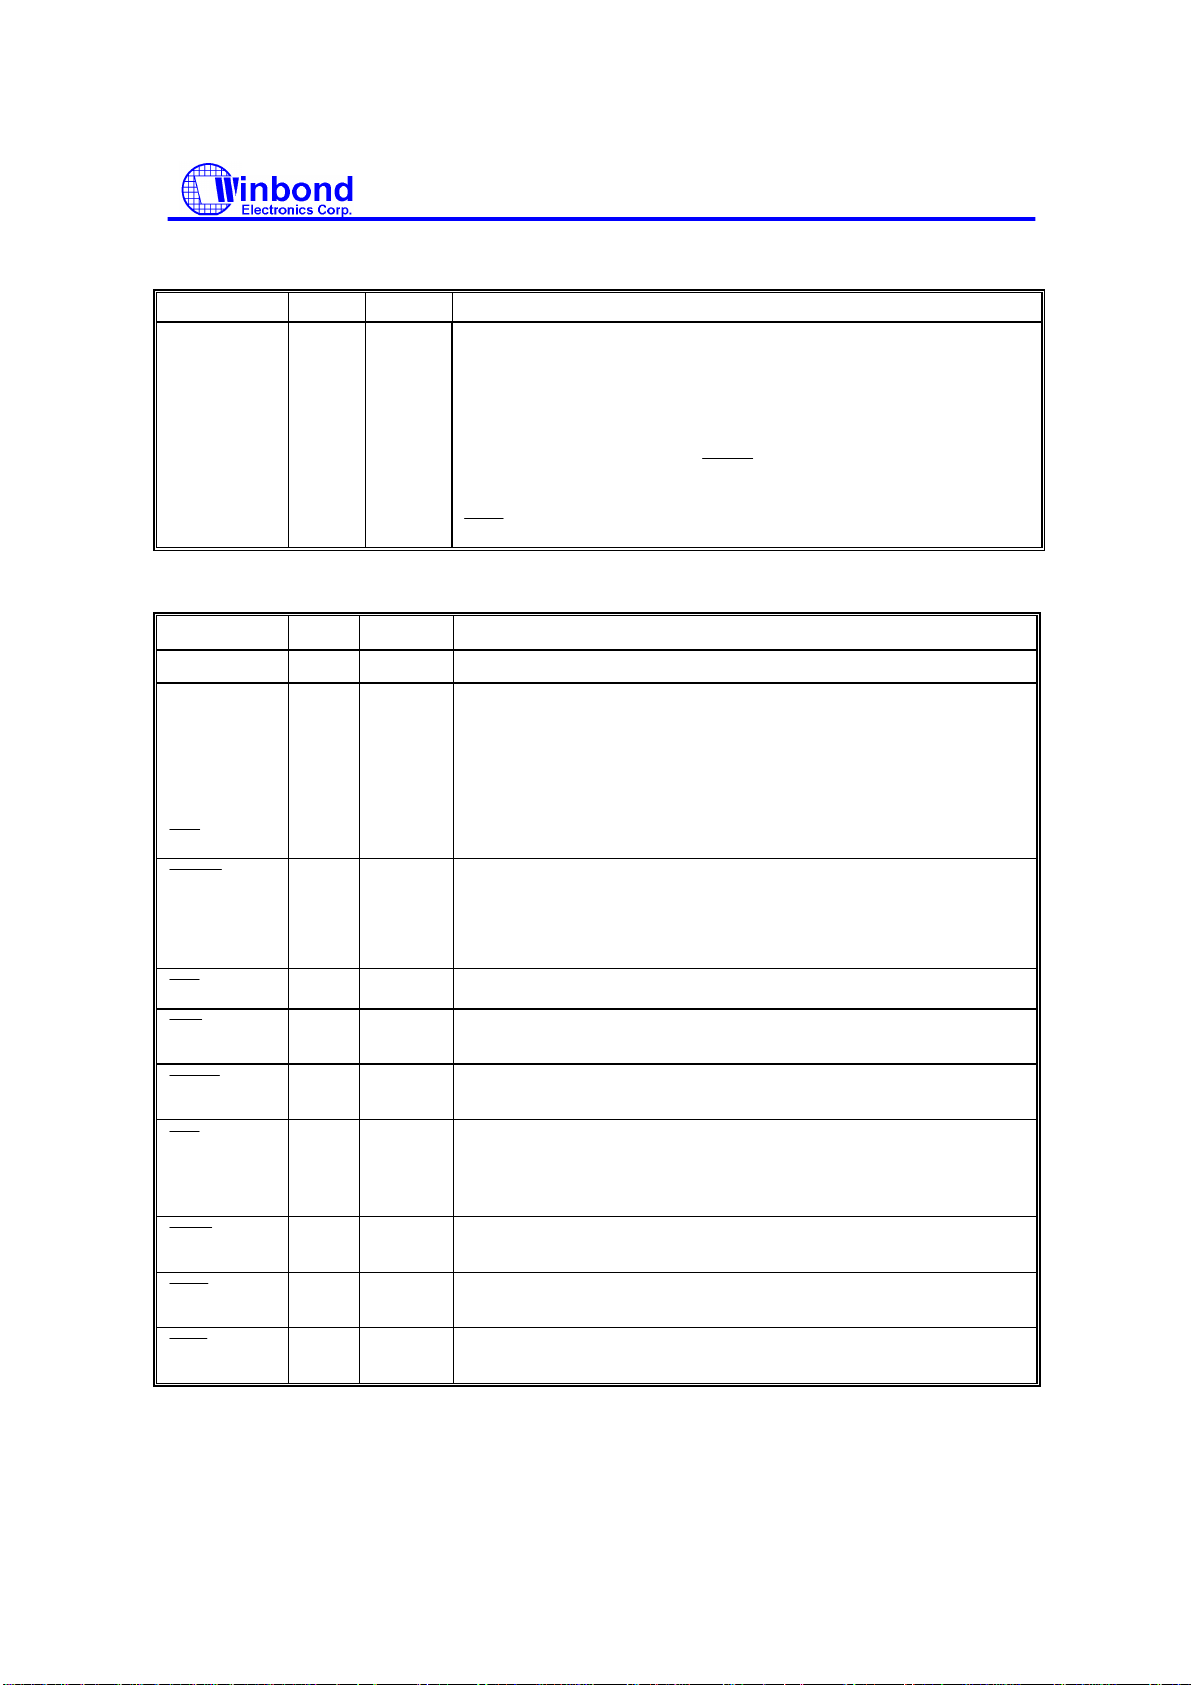
SYMBOL PIN I/O FUNCTION
PD7
23 I/O
OD
PRINTER MODE: PD7
24t
Parallel port data bus bit 7. Refer to description of the parallel port
for definition of this pin in ECP and EPP mode.
EXTENSION FDD MODE: This pin is a tri-state output.
EXTENSION 2FDD MODE:
24
This pin is for Extension FDD A; its function is the same as the
pin of FDC.
1.6 FDC Interface
SYMBOL PIN I/O FUNCTION
DRVDEN0 2 OD
DRVDEN1
GP10
(IRQIN1)
P12
3 OD
IO
Alternate Function from GP10: Interrupt channel input.
IO
OUT
5 OD
9 OD
10 OD
11 OD
12 OD
13 OD
14 OD
15 OD
Drive Density Select bit 0.
24
Drive Density Select bit 1. (CR2A bit 1_0 = 00, default)
24
General purpose I/O port 1 bit 0. (CR2A bit 1_0 = 01)
24t
KBC P12 I/O port. (CR2A bit 1_0 = 10)
24t
System Control Interrupt (CR2A bit 1_0 = 11)
12t
Head select. This open drain output determines which disk drive
24
head is active.
Logic 1 = side 0
Logic 0 = side 1
Write enable. An open drain output.
24
Write data. This logic low open drain writes pre-compensation
24
serial data to the selected FDD. An open drain output.
Step output pulses. This active low open drain output produces a
24
pulse to move the head to another track.
Direction of the head step motor. An open drain output.
24
Logic 1 = outward motion
Logic 0 = inward motion
Motor B On. When set to 0, this pin enables disk drive 1. This is
24
an open drain output.
Drive Select A. When set to 0, this pin enables disk drive A. This
24
is an open drain output.
Drive Select B. When set to 0, this pin enables disk drive B. This
24
is an open drain output.
PRELIMINARY
Publication Release Date: April 1998
-14- Revision 0.62
Page 23
W83977TF
MOA
DSKCHG
RDATA
WP
TRAK0
INDEX
1.6 FDC Interface, continued
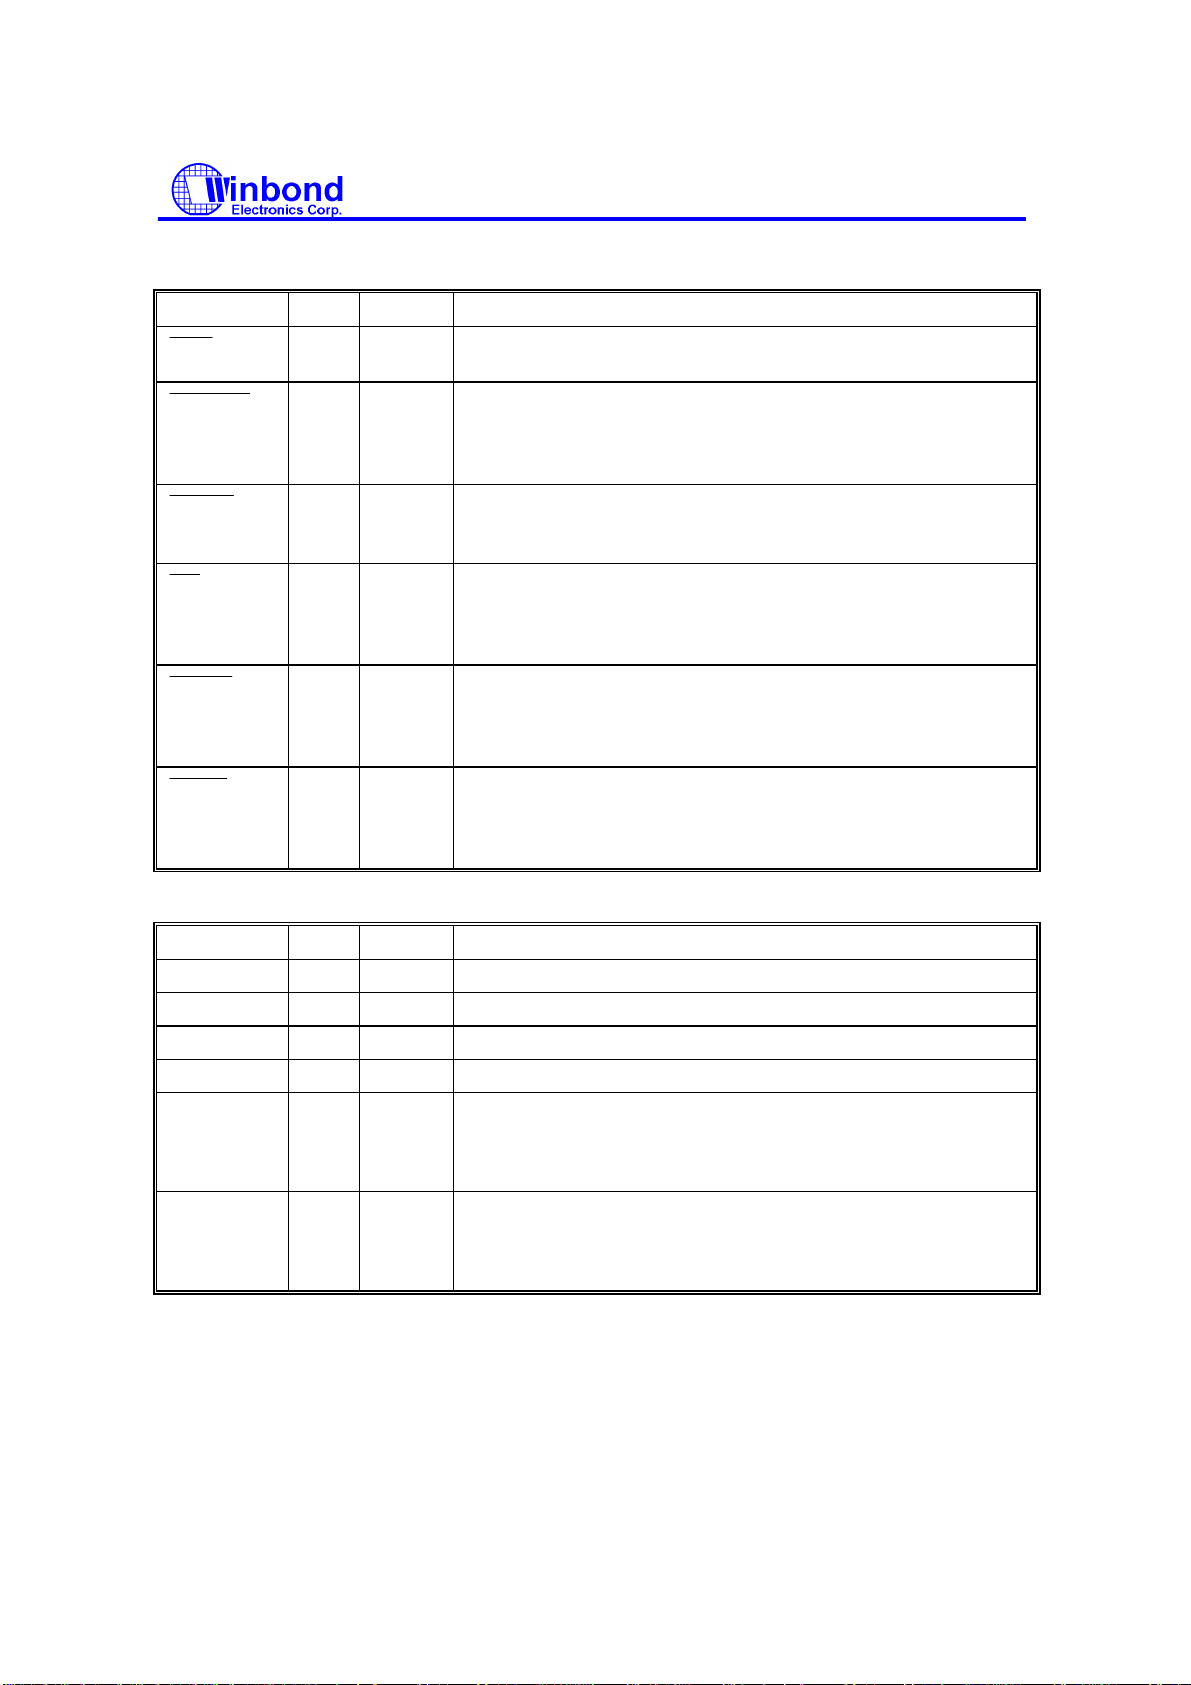
SYMBOL PIN I/O FUNCTION
Motor A On. When set to 0, this pin enables disk drive 0. This is
24
an open drain output.
Diskette change. This signal is active low at power on and
cs
whenever the diskette is removed. This input pin is pulled up
16 OD
4 IN
internally by a 1 KΩ resistor. The resistor can be disabled by bit 7
of L0-CRF0 (FIPURDWN).
6 IN
The read data input signal from the FDD. This input pin is pulled
cs
up internally by a 1 KΩ resistor. The resistor can be disabled by
bit 7 of L0-CRF0 (FIPURDWN).
7 IN
Write protected. This active low Schmitt input from the disk drive
cs
indicates that the diskette is write-protected. This input pin is
pulled up internally by a 1 KΩ resistor. The resistor can be
disabled by bit 7 of L0-CRF0 (FIPURDWN).
8 IN
Track 0. This Schmitt-triggered input from the disk drive is active
cs
low when the head is positioned over the outermost track. This
input pin is pulled up internally by a 1 KΩ resistor. The resistor
can be disabled by bit 7 of L0-CRF0 (FIPURDWN).
17 IN
This Schmitt-triggered input from the disk drive is active low when
cs
the head is positioned over the beginning of a track marked by an
index hole. This input pin is pulled up internally by a 1 KΩ resistor.
The resistor can be disabled by bit 7 of L0-CRF0 (FIPURDWN).
PRELIMINARY
1.7 KBC Interface
SYMBOL PIN I/O FUNCTION
KDATA 59 I/OD
MDATA 60 I/OD
KCLK 67 I/OD
MCLK 68 I/OD
GA20 56 I/O
GP11 I/O
(IRQIN2) Alternate Function from GP11: Interrupt channel input.
KBRST 57 I/O
GP12 I/O
(WDTO) Alternate Function 1 from GP12 : Watchdog timer output.
Keyboard Data
16u
PS2 Mouse Data
16u
Keyboard Clock
16u
PS2 Mouse Clock
16u
KBC GATE A20 (P21) Output. (CR2A bit 6 = 0, default)
12t
General purpose I/O port 1 bit 1. (CR2A bit 6 = 1)
12t
W83C45 Keyboard Reset (P20) Output. (CR2A bit 7 = 0, default)
12t
General purpose I/O port 1 bit 2. (CR2A bit 7 = 1)
12t
Publication Release Date: April 1998
-15 - Revision 0.62
Page 24
W83977TF
1.7 KBC Interface, continued
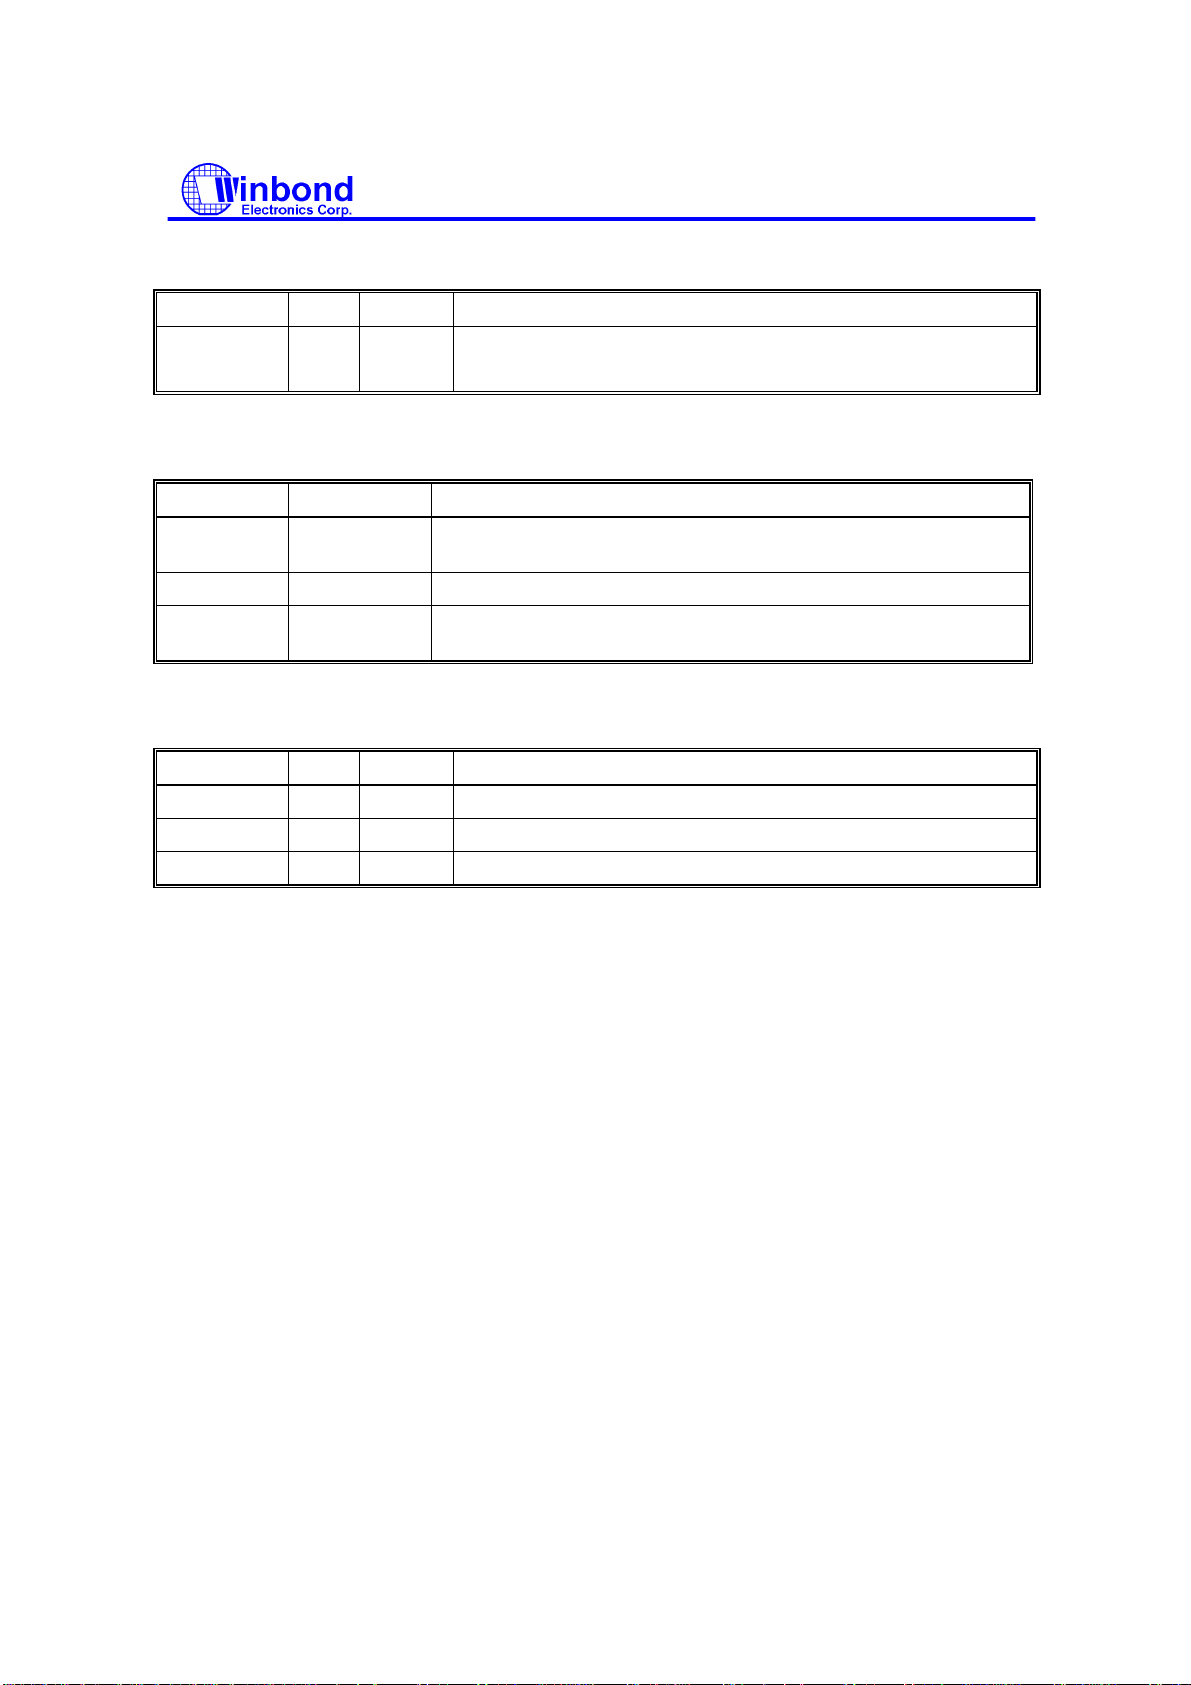
SYMBOL PIN I/O FUNCTION
KBLOCK 58 IN
GP13 I/O
W83C45 KINH (P17) Input. (CR2B bit 0 = 0, default)
ts
General purpose I/O port 1 bit 3. (CR2B bit 0 = 1)
16t
1.8 POWER PINS
SYMBOL PIN FUNCTION
VCC 20, 55, 85,
115
VSB 71 +5V stand-by power supply for the digital circuitry
GND 25, 62, 90,
120
+5V power supply for the digital circuitry
Ground
1.9 ACPI Interface
SYMBOL PIN I/O FUNCTION
VBAT 64 NA
XTAL1 63 IN
XTAL2 61 O
battery voltage input
32.768Khz Clock Input
C
32.768Khz Clock Output
8t
PRELIMINARY
Publication Release Date: April 1998
-16- Revision 0.62
Page 25
W83977TF
PRELIMINARY
2. FDC FUNCTIONAL DESCRIPTION
2.1 W83977TF FDC
The floppy disk controller of the W83977TF integrates all of the logic required for floppy disk control.
The FDC implements a PC/AT or PS/2 solution. All programmable options default to compatible
values. The FIFO provides better system performance in multi-master systems. The digital data
separator supports up to 2 M bits/sec data rate.
The FDC includes the following blocks: AT interface, Precompensation, Data Rate Selection, Digital
Data Separator, FIFO, and FDC Core.
2.1.1 AT interface
The interface consists of the standard asynchronous signals: RD, WR, A0-A3, IRQ, DMA control, and
a data bus. The address lines select between the configuration registers, the FIFO and control/status
registers. This interface can be switched between PC/AT, Model 30, or PS/2 normal modes. The PS/2
register sets are a superset of the registers found in a PC/AT.
2.1.2 FIFO (Data)
The FIFO is 16 bytes in size and has programmable threshold values. All command parameter
information and disk data transfers go through the FIFO. Data transfers are governed by the RQM and
DIO bits in the Main Status Register.
The FIFO defaults to disabled mode after any form of reset. This maintains PC/AT hardware
compatibility. The default values can be changed through the CONFIGURE command. The advantage
of the FIFO is that it allows the system a larger DMA latency without causing disk errors. The following
tables give several examples of the delays with a FIFO. The data are based upon the following formula:
THRESHOLD # × (1/DATA/RATE) *8 - 1.5 µS = DELAY
FIFO THRESHOLD MAXIMUM DELAY TO SERVICING AT 500K BPS
1 Byte
2 Byte
8 Byte
15 Byte
FIFO THRESHOLD MAXIMUM DELAY TO SERVICING AT 1M BPS
Data Rate
1 Byte
2 Byte
8 Byte
15 Byte
-17 - Revision 0.62
Data Rate
1 × 16 µS - 1.5 µS = 14.5 µS
2 × 16 µS - 1.5 µS = 30.5 µS
8 × 16 µS - 1.5 µS = 6.5 µS
15 × 16 µS - 1.5 µS = 238.5 µS
1 × 8 µS - 1.5 µS = 6.5 µS
2 × 8 µS - 1.5 µS = 14.5 µS
8 × 8 µS - 1.5 µS = 62.5 µS
15 × 8 µS - 1.5 µS = 118.5 µS
Publication Release Date: April 1998
Page 26
W83977TF
DACK
DACK
PRELIMINARY
At the start of a command the FIFO is always disabled and command parameters must be sent based
upon the RQM and DIO bit settings in the main status register. When the FDC enters the command
execution phase, it clears the FIFO of any data to ensure that invalid data are not transferred.
An overrun and underrun will terminate the current command and the data transfer. Disk writes will
complete the current sector by generating a 00 pattern and valid CRC. Reads require the host to
remove the remaining data so that the result phase may be entered.
DMA transfers are enabled with the SPECIFY command and are initiated by the FDC by activating the
DRQ pin during a data transfer command. The FIFO is enabled directly by asserting
addresses need not be valid.
Note that if the DMA controller is programmed to function in verify mode a pseudo read is performed by
the FDC based only on
mode (FIFO disabled) and is programmed to do a read. With the FIFO enabled the above operation is
performed by using the new VERIFY command. No DMA operation is needed.
2.1.3 Data Separator
The function of the data separator is to lock onto the incoming serial read data. When a lock is achieved
the serial front end logic of the chip is provided with a clock which is synchronized to the read data. The
synchronized clock, called the Data Window, is used to internally sample the serial data portion of the
bit cell, and the alternate state samples the clock portion. Serial to parallel conversion logic separates
the read data into clock and data bytes.
The Digital Data Separator (DDS) has three parts: control logic, error adjustment, and speed tracking.
The DDS circuit cycles once every 12 clock cycles ideally. Any data pulse input will be synchronized and
then adjusted by immediate error adjustment. The control logic will generate RDD and RWD for every
pulse input. During any cycle where no data pulse is present, the DDS cycles are based on speed. A
digital integrator is used to keep track of the speed changes in the input data stream.
. This mode is only available when the FDC has been configured into byte
and
2.1.4 Write Precompensation
The write precompensation logic is used to minimize bit shifts in the RDDATA stream from the disk
drive. Shifting of bits is a known phenomenon in magnetic media and is dependent on the disk media
and the floppy drive.
The FDC monitors the bit stream that is being sent to the drive. The data patterns that require
precompensation are well known. Depending upon the pattern, the bit is shifted either early or late
relative to the surrounding bits.
2.1.5 Perpendicular Recording Mode
The FDC is also capable of interfacing directly to perpendicular recording floppy drives. Perpendicular
recording differs from the traditional longitudinal method in that the magnetic bits are oriented vertically.
This scheme packs more data bits into the same area.
FDCs with perpendicular recording drives can read standard 3.5" floppy disks and can read and write
perpendicular media. Some manufacturers offer drives that can read and write standard and
perpendicular media in a perpendicular media drive.
A single command puts the FDC into perpendicular mode. All other commands operate as they
normally do. The perpendicular mode requires a 1 Mbps data rate for the FDC. At this data rate the
FIFO eases the host interface bottleneck due to the speed of data transfer to or from the disk.
Publication Release Date: April 1998
-18- Revision 0.62
Page 27

W83977TF
PRELIMINARY
2.1.6 FDC Core
The W83977TF FDC is capable of performing twenty commands. Each command is initiated by a multibyte transfer from the microprocessor. The result can also be a multi-byte transfer back to the
microprocessor. Each command consists of three phases: command, execution, and result.
Command
The microprocessor issues all required information to the controller to perform a specific operation.
Execution
The controller performs the specified operation.
Result
After the operation is completed, status information and other housekeeping information is provided to
the microprocessor.
2.1.7 FDC Commands
Command Symbol Descriptions:
C: Cylinder number 0 - 256
D: Data Pattern
DIR: Step Direction
DIR = 0, step out
DIR = 1, step in
DS0: Disk Drive Select 0
DS1: Disk Drive Select 1
DTL: Data Length
EC: Enable Count
EOT: End of Track
EFIFO: Enable FIFO
EIS: Enable Implied Seek
EOT: End of track
FIFOTHR: FIFO Threshold
GAP: Gap length selection
GPL: Gap Length
H: Head number
HDS: Head number select
HLT: Head Load Time
HUT: Head Unload Time
LOCK: Lock EFIFO, FIFOTHR, PTRTRK bits prevent affected by software reset
MFM: MFM or FM Mode
MT: Multitrack
N: The number of data bytes written in a sector
NCN: New Cylinder Number
ND: Non-DMA Mode
OW: Overwritten
PCN: Present Cylinder Number
POLL: Polling Disable
PRETRK: Precompensation Start Track Number
Publication Release Date: April 1998
-19 - Revision 0.62
Page 28
W83977TF
W
W
PRELIMINARY
R: Record
RCN: Relative Cylinder Number
R/W: Read/Write
SC: Sector/per cylinder
SK: Skip deleted data address mark
SRT: Step Rate Time
ST0: Status Register 0
ST1: Status Register 1
ST2: Status Register 2
ST3: Status Register 3
WG: Write gate alters timing of WE
(1) Read Data
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W MT MFM SK 0 0 1 1 0 Command codes
W
W
W
Execution Data transfer between the
Result R
R
W 0 0 0 0 0 HDS DS1 DS0
W
W
R
R
R
R
R
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
-------------------- EOT -----------------------
-------------------- GPL -----------------------
-------------------- DTL -----------------------
-------------------- ST0 -----------------------
-------------------- ST1 -----------------------
-------------------- ST2 -----------------------
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
Sector ID information prior
to command execution
FDD and system
Status information after
command execution
Sector ID information after
command execution
Publication Release Date: April 1998
-20- Revision 0.62
Page 29
W83977TF
W
W
W
PRELIMINARY
(2) Read Deleted Data
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W MT MFM SK 0 1 1 0 0 Command codes
W
W
Execution Data transfer between the
Result R
W 0 0 0 0 0 HDS DS1 DS0
---------------------- C ------------------------
W
W
R
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
-------------------- EOT -----------------------
-------------------- GPL -----------------------
-------------------- DTL -----------------------
-------------------- ST0 -----------------------
-------------------- ST1 -----------------------
Sector ID information prior
to command execution
FDD and system
Status information after
command execution
R
R
R
R
R
-------------------- ST2 -----------------------
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
Sector ID information after
command execution
Publication Release Date: April 1998
-21 - Revision 0.62
Page 30
W83977TF
W
W
PRELIMINARY
(3) Read A Track
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 MFM 0 0 0 0 1 0 Command codes
W 0 0 0 0 0 HDS DS1 DS0
W
W
W
W
W
Execution
Result R
R
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
-------------------- EOT -----------------------
-------------------- GPL -----------------------
-------------------- DTL -----------------------
Data transfer between the
-------------------- ST0 -----------------------
-------------------- ST1 -----------------------
Sector ID information prior to
command execution
FDD and system; FDD reads
contents of all cylinders from
index hole to EOT
Status information after
command execution
R
R
R
R
R
-------------------- ST2 -----------------------
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
Sector ID information after
command execution
Publication Release Date: April 1998
-22- Revision 0.62
Page 31
W83977TF
W
W
PRELIMINARY
(4) Read ID
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 MFM 0 0 1 0 1 0 Command codes
W 0 0 0 0 0 HDS DS1 DS0
Execution
Result R
R
(5) Verify
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
R
R
R
R
R
The first correct ID
-------------------- ST0 -----------------------
-------------------- ST1 -----------------------
-------------------- ST2 -----------------------
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
information on the cylinder
is stored in Data Register
Status information after
command execution
Disk status after the
command has been
completed
Command W MT MFM SK 1 0 1 1 0 Command codes
W EC 0 0 0 0 HDS DS1 DS0
W
W
W
-------------------- DTL/SC -------------------
Execution No data transfer takes
Result R
R
W
R
R
R
R
R
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
-------------------- EOT -----------------------
-------------------- GPL -----------------------
-------------------- ST0 -----------------------
-------------------- ST1 -----------------------
-------------------- ST2 -----------------------
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
Sector ID information prior
to command execution
place
Status information after
command execution
Sector ID information after
command execution
Publication Release Date: April 1998
-23 - Revision 0.62
Page 32
W83977TF
W
W
W
PRELIMINARY
(6) Version
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 0 0 1 0 0 0 0 Command code
Result R 1 0 0 1 0 0 0 0 Enhanced controller
(7) Write Data
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W MT MFM 0 0 0 1 0 1 Command codes
W 0 0 0 0 0 HDS DS1 DS0
W
W
W
W
Execution Data transfer between the
Result R
R
R
R
R
R
R
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
-------------------- EOT -----------------------
-------------------- GPL -----------------------
-------------------- DTL -----------------------
-------------------- ST0 -----------------------
-------------------- ST1 -----------------------
-------------------- ST2 -----------------------
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
Sector ID information prior
to Command execution
FDD and system
Status information after
Command execution
Sector ID information after
Command execution
Publication Release Date: April 1998
-24- Revision 0.62
Page 33
W83977TF
W
W
PRELIMINARY
(8) Write Deleted Data
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W MT MFM 0 0 1 0 0 1 Command codes
W 0 0 0 0 0 HDS DS1 DS0
W
W
W
Execution Data transfer between the
Result R
R
W
W
R
R
R
R
R
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
-------------------- EOT -----------------------
-------------------- GPL -----------------------
-------------------- DTL -----------------------
-------------------- ST0 -----------------------
-------------------- ST1 -----------------------
-------------------- ST2 -----------------------
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
Sector ID information prior
to command execution
FDD and system
Status information after
command execution
Sector ID information after
command execution
Publication Release Date: April 1998
-25 - Revision 0.62
Page 34
W83977TF
W
W
PRELIMINARY
(9) Format A Track
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 MFM 0 0 1 1 0 1 Command codes
W 0 0 0 0 0 HDS DS1 DS0
W
W
W
Execution
for Each
Sector
Repeat:
Result R
R
W
W
W
R
R
R
R
R
---------------------- N ------------------------
--------------------- SC -----------------------
--------------------- GPL ---------------------
---------------------- D ------------------------
---------------------- C ------------------------
---------------------- H ------------------------
---------------------- R ------------------------
---------------------- N ------------------------
-------------------- ST0 -----------------------
-------------------- ST1 -----------------------
-------------------- ST2 -----------------------
---------------- Undefined -------------------
---------------- Undefined -------------------
---------------- Undefined -------------------
---------------- Undefined -------------------
Bytes/Sector
Sectors/Cylinder
Gap 3
Filler Byte
Input Sector Parameters
Status information after
command execution
(10) Recalibrate
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 0 0 0 0 1 1 1 Command codes
W 0 0 0 0 0 0 DS1 DS0
Execution Head retracted to Track 0
Interrupt
(11) Sense Interrupt Status
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 0 0 0 1 0 0 0 Command code
Result
-26- Revision 0.62
R
R
---------------- ST0 -------------------------
---------------- PCN -------------------------
Status information at the end
of each seek operation
Publication Release Date: April 1998
Page 35
W83977TF
PRELIMINARY
(12) Specify
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 0 0 0 0 0 1 1 Command codes
(13) Seek
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 0 0 0 1 1 1 1 Command codes
W W 0 0 0 0 0 HDS DS1 DS0
Execution R Head positioned over proper
(14) Configure
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
W W | ---------SRT ----------- | --------- HUT ---------- |
|------------ HLT ----------------------------------| ND
-------------------- NCN -----------------------
cylinder on diskette
Command W 0 0 0 1 0 0 1 1 Configure information
W
Execution Internal registers written
(15) Relative Seek
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 1 DIR 0 0 1 1 1 1 Command codes
0 0 0 0 0 0 0 0
W
W
W
W
0 EIS EFIFO POLL | ------ FIFOTHR ----|
| --------------------PRETRK ----------------------- |
0 0 0 0 0 HDS DS1 DS0
| -------------------- RCN ---------------------------- |
Publication Release Date: April 1998
-27 - Revision 0.62
Page 36
W83977TF
PRELIMINARY
(16) Dumpreg
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 0 0 0 1 1 1 0 Registers placed in FIFO
Result
(17) Perpendicular Mode
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 0 0 1 0 0 1 0 Command Code
W OW 0 D3 D2 D1 D0 GAP WG
R
R
R
R
R
R
R
R
R
R
----------------------- PCN-Drive 0--------------------
----------------------- PCN-Drive 1 -------------------
----------------------- PCN-Drive 2--------------------
----------------------- PCN-Drive 3 -------------------
--------SRT ------------------ | --------- HUT --------
----------- HLT -----------------------------------| ND
------------------------ SC/EOT ---------------------LOCK 0 D3 D2 D1 D0 GAP WG
0 EIS EFIFO POLL | ------ FIFOTHR --------
-----------------------PRETRK -------------------------
(18) Lock
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W LOCK 0 0 1 0 1 0 0 Command Code
Result R 0 0 0 LOCK 0 0 0 0
(19) Sense Drive Status
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W 0 0 0 0 0 1 0 0 Command Code
W 0 0 0 0 0 HDS DS1 DS0
Result
(20) Invalid
PHASE R/W D7 D6 D5 D4 D3 D2 D1 D0 REMARKS
Command W ------------- Invalid Codes ----------------- Invalid codes (no operation-
Result R
R
---------------- ST3 ------------------------- Status information about
-------------------- ST0 ----------------------
disk drive
FDC goes to standby state)
ST0 = 80H
Publication Release Date: April 1998
-28- Revision 0.62
Page 37
W83977TF
DRV2
STEP
TRAK
0
TRAK
0
PRELIMINARY
2.2 Register Descriptions
There are several status, data, and control registers in W83977TF. These registers are defined below:
ADDRESS REGISTER
OFFSET READ WRITE
base address + 0
base address + 1
base address + 2
base address + 3
base address + 4 MS REGISTER DR REGISTER
base address + 5 DT (FIFO) REGISTER DT (FIFO) REGISTER
base address + 7 DI REGISTER CC REGISTER
2.2.1 Status Register A (SA Register) (Read base address + 0)
This register is used to monitor several disk interface pins in PS/2 and Model 30 modes. In PS/2 mode,
the bit definitions for this register are as follows:
SA REGISTER
SB REGISTER
TD REGISTER
2
34567
1
DO REGISTER
TD REGISTER
0
INIT PENDING (Bit 7):
This bit indicates the value of the floppy disk interrupt output.
(Bit 6):
0 A second drive has been installed
1 A second drive has not been installed
STEP (Bit 5):
This bit indicates the complement of
(Bit 4):
This bit indicates the value of
HEAD (Bit 3):
output.
input.
DIR
WP
INDEX
HEAD
TRAK0
STEP
DRV2
INIT PENDING
Publication Release Date: April 1998
-29 - Revision 0.62
Page 38
W83977TF
HEAD
INDEX
INDEX
WP
INIT PENDING
STEP
TRAK
0
HEAD
HEAD
This bit indicates the complement of
output.
0 side 0
1 side 1
(Bit 2):
This bit indicates the value of
output.
(Bit 1):
0disk is write-protected
1disk is not write-protected
DIR (Bit 0)
This bit indicates the direction of head movement.
0 outward direction
1 inward direction
In PS/2 Model 30 mode, the bit definitions for this register are as follows:
2
34567
1
0
PRELIMINARY
INIT PENDING (Bit 7):
This bit indicates the value of the floppy disk interrupt output.
DRQ (Bit 6):
This bit indicates the value of DRQ output pin.
STEP F/F (Bit 5):
This bit indicates the complement of latched
TRAK0 (Bit 4):
This bit indicates the complement of
(Bit 3):
This bit indicates the value of
output.
0 side 1
1 side 0
input.
output.
DIR
WP
INDEX
HEAD
TRAK0
STEP F/F
DRQ
Publication Release Date: April 1998
-30- Revision 0.62
Page 39
W83977TF
INDEX
DIR
RDATA
MOB
MOA
PRELIMINARY
INDEX (Bit 2):
This bit indicates the complement of
WP (Bit 1):
0 disk is not write-protected
1 disk is write-protected
(Bit 0)
This bit indicates the direction of head movement.
0 inward direction
1 outward direction
2.2.2 Status Register B (SB Register) (Read base address + 1)
This register is used to monitor several disk interface pins in PS/2 and Model 30 modes. In PS/2 mode,
the bit definitions for this register are as follows:
1
1
output.
2
34567
1
0
MOT EN A
MOT EN B
WE
RDATA Toggle
WDATA Toggle
Drive SEL0
Drive SEL0 (Bit 5):
This bit indicates the status of DO REGISTER bit 0 (drive select bit 0).
WDATA Toggle (Bit 4):
This bit changes state at every rising edge of the WD output pin.
RDATA Toggle (Bit 3):
This bit changes state at every rising edge of the
output pin.
WE (Bit 2):
This bit indicates the complement of the WE output pin.
MOT EN B (Bit 1)
This bit indicates the complement of the
output pin.
MOT EN A (Bit 0)
This bit indicates the complement of the
output pin.
In PS/2 Model 30 mode, the bit definitions for this register are as follows:
Publication Release Date: April 1998
-31 - Revision 0.62
Page 40
W83977TF
DRV2
DRV2
DSB
DSB
DSA
DSA
RDATA
DSD
DSC
(Bit 7):
0 A second drive has been installed
1 A second drive has not been installed
(Bit 6):
This bit indicates the status of
output pin.
(Bit 5):
This bit indicates the status of
output pin.
WD F/F(Bit 4):
PRELIMINARY
2
34567
1
0
DSC
DSD
WE F/F
RDATA F/F
WD F/F
DSA
DSB
This bit indicates the complement of the latched WD output pin at every rising edge of the WD output
pin.
RDATA F/F(Bit 3):
This bit indicates the complement of the latched
output pin .
WE F/F (Bit 2):
This bit indicates the complement of latched WE output pin.
(Bit 1):
0 Drive D has been selected
1 Drive D has not been selected
(Bit 0):
0 Drive C has been selected
1 Drive C has not been selected
Publication Release Date: April 1998
-32- Revision 0.62
Page 41
W83977TF
PRELIMINARY
2.2.3 Digital Output Register (DO Register) (Write base address + 2)
The Digital Output Register is a write-only register controlling drive motors, drive selection, DRQ/IRQ
enable, and FDC resetting. All the bits in this register are cleared by the MR pin. The bit definitions are
as follows:
7 6
5 4
2.2.4 Tape Drive Register (TD Register) (Read base address + 3)
This register is used to assign a particular drive number to the tape drive support mode of the data
separator. This register also holds the media ID, drive type, and floppy boot drive information of the
floppy disk drive. In normal floppy mode, this register includes only bit 0 and 1. The bit definitions are as
follows:
X X
3
2
X X X X
1-0
Drive Select: 00 select drive A
Floppy Disk Controller Reset
Active low resets FDC
DMA and INT Enable
Active high enable DRQ/IRQ
Motor Enable A. Motor A on when active high
Motor Enable B. Motor B on when active high
Motor Enable C. Motor C on when active high
Motor Enable D. Motor D on when active high
2
34567
1
0
01 select drive B
10 select drive C
11 select drive D
Tape sel 0
Tape sel 1
If three mode FDD function is enabled (EN3MODE = 1 in Logical Device 0 CRF0 bit:0), the bit definitions
are as follows:
2
34567
1
0
Tape Sel 0
Tape Sel 1
Floppy boot drive 0
Floppy boot drive 1
Drive type ID0
Drive type ID1
Media ID0
Media ID1
Publication Release Date: April 1998
-33 - Revision 0.62
Page 42
W83977TF
PRELIMINARY
Media ID1 Media ID0 (Bit 7, 6):
These two bits are read only. These two bits reflect the value of Logical Device 0 CRF1 bit 4,5.
Drive type ID1 Drive type ID0 (Bit 5, 4):
These two bits reflect two of the bits of Logical Device 0 CRF2. Which two bits are reflected depends on
the last drive selected in the DO REGISTER.
Floppy Boot drive 1, 0 (Bit 3, 2):
These two bits reflect the value of Logical Device 0 CRF1 bit 7,6.
Tape Sel 1, Tape Sel 0 (Bit 1, 0):
These two bits assign a logical drive number to the tape drive. Drive 0 is not available as a tape drive
and is reserved as the floppy disk boot drive.
TAPE SEL 1 TAPE SEL 0 DRIVE SELECTED
0 0 None
0 1 1
1 0 2
1 1 3
2.2.5 Main Status Register (MS Register) (Read base address + 4)
The Main Status Register is used to control the flow of data between the microprocessor and the
controller. The bit definitions for this register are as follows:
6
7
5 4 3 2 1
0
FDD 0 Busy, (D0B = 1), FDD number 0 is in the SEEK mode.
FDD 1 Busy, (D1B = 1), FDD number 1 is in the SEEK mode.
FDD 2 Busy, (D2B = 1), FDD number 2 is in the SEEK mode.
FDD 3 Busy, (D3B = 1), FDD number 3 is in the SEEK mode.
FDC Busy, (CB). A read or write command is in the process when CB = HIGH.
Non-DMA mode, the FDC is in the non-DMA mode, this bit is set only during the
execution phase in non-DMA mode.
Transition to LOW state indicates execution phase has ended.
DATA INPUT/OUTPUT, (DIO). If DIO= HIGH then transfer is from Data Register to the processor.
If DIO = LOW then transfer is from processor to Data Register.
Request for Master (RQM). A high on this bit indicates Data Register is ready to send or receive data to or from the processor.
2.2.6 Data Rate Register (DR Register) (Write base address + 4)
The Data Rate Register is used to set the transfer rate and write precompensation. The data rate of the
FDC is programmed by the CC REGISTER for PC-AT and PS/2 Model 30 and PS/2 mode, and not by
the DR REGISTER. The real data rate is determined by the most recent write to either of the DR
REGISTER or CC REGISTER.
Publication Release Date: April 1998
-34- Revision 0.62
Page 43
W83977TF
POWER DOWN
PRELIMINARY
34567
0
S/W RESET (Bit 7):
This bit is the software reset bit.
POWER-DOWN (Bit 6):
0 FDC in normal mode
1 FDC in power-down mode
PRECOMP2 PRECOMP1 PRECOMP0 (Bit 4, 3, 2):
These three bits select the value of write precompensation. The following tables show the
precompensation values for the combination of these bits.
PRECOMP
2 1 0
250K - 1 Mbps 2 Mbps Tape drive
0 0 0 Default Delays Default Delays
0 0 1 41.67 nS 20.8 nS
0 1 0 83.34 nS 41.17 nS
0 1 1 125.00 nS 62.5nS
1 0 0 166.67 nS 83.3 nS
1 0 1 208.33 nS 104.2 nS
1 1 0 250.00 nS 125.00 nS
1 1 1 0.00 nS (disabled) 0.00 nS (disabled)
1
2
0
DRATE0
DRATE1
PRECOMP0
PRECOMP1
PRECOMP2
S/W RESET
PRECOMPENSATION DELAY
Publication Release Date: April 1998
-35 - Revision 0.62
Page 44
W83977TF
RWC
RWC
RWC
RWC
11 Abnormal termination because the ready signal from FDD changed state during command execution
PRELIMINARY
DATA RATE DEFAULT PRECOMPENSATION DELAYS
250 KB/S 125 nS
300 KB/S 125 nS
500 KB/S 125 nS
1 MB/S 41.67nS
2 MB/S 20.8 nS
DRATE1 DRATE0 (Bit 1, 0):
These two bits select the data rate of the FDC and reduced write current control.
00 500 KB/S (MFM), 250 KB/S (FM),
01 300 KB/S (MFM), 150 KB/S (FM),
10 250 KB/S (MFM), 125 KB/S (FM),
11 1 MB/S (MFM), Illegal (FM),
The 2 MB/S data rate for Tape drive is only supported by setting 01 to DRATE1 and DRATE0 bits, as
well as setting 10 to DRT1 and DRT0 bits which are two of the Configure Register CRF4 or CRF5 bits in
logic device 0. Please refer to the function description of CRF4 or CRF5 and data rate table for
individual data rates setting.
2.2.7 FIFO Register (R/W base address + 5)
The Data Register consists of four status registers in a stack with only one register presented to the data
bus at a time. This register stores data, commands, and parameters and provides diskette-drive status
information. Data bytes are passed through the data register to program or obtain results after a
command. In the W83977TF, this register defaults to FIFO disabled mode after reset. The FIFO can
change its value and enable its operation through the CONFIGURE command.
Status Register 0 (ST0)
7-6 5
3 2 1-0
4
= 1
= 0
= 0
= 1
US1, US0 Drive Select:
00 Drive A selected
01 Drive B selected
10 Drive C selected
11 Drive D selected
HD Head address:
1 Head selected
0 Head selected
NR Not Ready:
1 Drive is not ready
0 Drive is ready
EC Equipment Check:
1 When a fault signal is received from the FDD or the track
0 signal fails to occur after 77 step pulses
0 No error
SE Seek end:
1 seek end
0 seek error
IC Interrupt Code:
00 Normal termination of command
01 Abnormal termination of command
10 Invalid command issue
-36- Revision 0.62
Publication Release Date: April 1998
Page 45
W83977TF
1 During execution of the Scan command, if the equal condition is satisfied
WP Write Protected
Status Register 1 (ST1)
Status Register 2 (ST2)
7 0
56
PRELIMINARY
234567
01
Missing Address Mark. 1 When the FDC cannot detect the data address mark
or the data address mark has been deleted.
NW (Not Writable). 1 If a write Protect signal is detected from the diskette drive during
execution of write data.
ND (No DATA). 1 If specified sector cannot be found during execution of a read, write or verifly data.
Not used. This bit is always 0.
OR (Over Rum). 1 If the FDC is not serviced by the host system within a certain time interval during data transfer.
DE (data Error).1 When the FDC detects a CRC error in either the ID field or the data field.
Not used. This bit is always 0.
EN (End of track). 1 When the FDC tries to access a sector beyond the final sector of a cylinder.
1
234
MD (Missing Address Mark in Data Field).
1 If the FDC cannot find a data address mark
(or the address mark has been deleted)
when reading data from the media
0 No error
BC (Bad Cylinder)
1 Bad Cylinder
0 No error
SN (Scan Not satisfied)
1 During execution of the Scan command
0 No error
SH (Scan Equal Hit)
0 No error
WC (Wrong Cylinder)
1 Indicates wrong Cylinder
DD (Data error in the Data field)
1 If the FDC detects a CRC error in the data field
0 No error
CM (Control Mark)
1 During execution of the read data or scan command
0 No error
Not used. This bit is always 0
Status Register 3 (ST3)
6
7
4
5
3
12
0
US0 Unit Select 0
US1 Unit Select 1
HD Head Address
TS Two-Side
TO Track 0
RY Ready
FT Fault
Publication Release Date: April 1998
-37 - Revision 0.62
Page 46
W83977TF
DSKCHG
x
During a read of this register, these bits are in tri-state
DSKCHG
DSKCHG
HIGH DENS
34567
PRELIMINARY
2.2.8 Digital Input Register (DI Register) (Read base address + 7)
The Digital Input Register is an 8-bit read-only register used for diagnostic purposes. In a PC/XT or AT
only Bit 7 is checked by the BIOS. When the register is read, Bit 7 shows the complement of
while other bits of the data bus remain in tri-state. Bit definitions are as follows:
567
xxx
x
In the PS/2 mode, the bit definitions are as follows:
1 111
DSKCHG (Bit 7):
This bit indicates the complement of the
Bit 6-3: These bits are always a logic 1 during a read.
DRATE1 DRATE0 (Bit 2, 1):
These two bits select the data rate of the FDC. Refer to the DR register bits 1 and 0 for the settings
corresponding to the individual data rates.
(Bit 0):
0 500 KB/S or 1 MB/S data rate (high density FDD)
1 250 KB/S or 300 KB/S data rate
In the PS/2 Model 30 mode, the bit definitions are as follows:
0 00
01234
xxx
Reserved for the hard disk controller
DSKCHG
34567
2
input.
2
0
1
HIGH DENS
DRATE0
DRATE1
0
1
,
DSKCHG (Bit 7):
-38- Revision 0.62
DRATE0
DRATE1
NOPREC
DMAEN
DSKCHG
Publication Release Date: April 1998
Page 47
W83977TF
DSKCHG
PRELIMINARY
This bit indicates the status of
Bit 6-4: These bits are always a logic 1 during a read.
DMAEN (Bit 3):
This bit indicates the value of DO REGISTER bit 3.
NOPREC (Bit 2):
This bit indicates the value of CC REGISTER NOPREC bit.
DRATE1 DRATE0 (Bit 1, 0):
These two bits select the data rate of the FDC.
2.2.9 Configuration Control Register (CC Register) (Write base address + 7)
This register is used to control the data rate. In the PC/AT and PS/2 mode, the bit definitions are as
follows:
7
input.
4
5
6
2
3
1
0
x x x x x x
DRATE0
X: Reserved
Bit 7-2: Reserved. These bits should be set to 0.
DRATE1 DRATE0 (Bit 1, 0):
These two bits select the data rate of the FDC.
In the PS/2 Model 30 mode, the bit definitions are as follows:
2
1
X X
34567
X X X
DRATE1
0
DRATE0
DRATE1
NOPREC
X: Reserved
Bit 7-3: Reserved. These bits should be set to 0.
NOPREC (Bit 2):
This bit indicates no precompensation. It has no function and can be set by software.
DRATE1 DRATE0 (Bit 1, 0):
These two bits select the data rate of the FDC.
Publication Release Date: April 1998
-39 - Revision 0.62
Page 48
W83977TF
PRELIMINARY
3. UART PORT
3.1 Universal Asynchronous Receiver/Transmitter (UART A, UART B)
The UARTs are used to convert parallel data into serial format on the transmit side and convert serial
data to parallel format on the receiver side. The serial format, in order of transmission and reception, is
a start bit, followed by five to eight data bits, a parity bit (if programmed) and one, one and half (five-bit
format only) or two stop bits. The UARTs are capable of handling divisors of 1 to 65535 and producing
a 16x clock for driving the internal transmitter logic. Provisions are also included to use this 16x clock to
drive the receiver logic. The UARTs also support the MIDI data rate. Furthermore, the UARTs also
include complete modem control capability and a processor interrupt system that may be software
trailed to the computing time required to handle the communication link. The UARTs have a FIFO
mode to reduce the number of interrupts presented to the CPU. In each UART, there are 16-byte FIFOs
for both receive and transmit mode.
3.2 Register Address
3.2.1 UART Control Register (UCR) (Read/Write)
The UART Control Register controls and defines the protocol for asynchronous data communications,
including data length, stop bit, parity, and baud rate selection.
6
7 0
45
2
3
1
Data length select bit 0 (DLS0)
Data length select bit 1(DLS1)
Multiple stop bits enable (MSBE)
Parity bit enable (PBE)
Even parity enable (EPE)
Parity bit fixed enable (PBFE)
Set silence enable (SSE)
Baudrate divisor latch access bit (BDLAB)
Bit 7: BDLAB. When this bit is set to a logical 1, designers can access the divisor (in 16-bit binary format)
from the divisor latches of the baudrate generator during a read or write operation. When this bit
is reset, the Receiver Buffer Register, the Transmitter Buffer Register, or the Interrupt Control
Register can be accessed.
Bit 6: SSE. A logical 1 forces the Serial Output (SOUT) to a silent state (a logical 0). Only IRTX is
affected by this bit; the transmitter is not affected.
Bit 5: PBFE. When PBE and PBFE of UCR are both set to a logical 1,
(1) if EPE is logical 1, the parity bit is fixed as logical 0 to transmit and check.
(2) if EPE is logical 0, the parity bit is fixed as logical 1 to transmit and check.
Publication Release Date: March 1998
- 40 - Revision 0.62
Page 49
PRELIMINARY
TABLE 3-1 UART Register Bit Map
W83977TF
Register Address Base
+ 0
BDLAB = 0
+ 0
BDLAB = 0
+ 1
BDLAB = 0
+ 2 Interrupt Status
+ 2 UART FIFO
+ 3 UART Control
+ 4 Handshake
+ 5 UART Status
+ 6 Handshake
+ 7 User Defined
+ 0
BDLAB = 1
+ 1
BDLAB = 1
Receiver
Register
(Read Only)
Transmitter
Buffer Register
(Write Only)
Interrupt
Control
Register
Register
(Read Only)
Control
Register
(Write Only)
Register
Control
Register
Register
Status Register
Register
Baudrate
Divisor Latch
Baudrate
Divisor Latch
*: Bit 0 is the least significant bit. The least significant bit is the first bit serially transmitted or received.
**: These bits are always 0 in 16450 Mode.
Buffer
Low
High
Bit Number
RBR
TBR
ICR
ISR
UFR
UCR
HCR
USR
HSR
UDR
BLL
BHL
0 1 2 3 4 5 6 7
RX Data
Bit 0
TX Data
Bit 0
RBR Data
Ready
Interrupt
Enable
(ERDRI)
"0" if Interrupt
Pending
FIFO
Enable
Data
Length
Select
Bit 0
(DLS0)
Data
Terminal
Ready
(DTR)
RBR Data
Ready
(RDR)
CTS
Toggling
(TCTS)
Bit 0 Bit 1 Bit 2 Bit 3 Bit 4 Bit 5 Bit 6 Bit 7
Bit 0 Bit 1 Bit 2 Bit 3 Bit 4 Bit 5 Bit 6 Bit 7
Bit 8 Bit 9 Bit 10 Bit 11 Bit 12 Bit 13 Bit 14 Bit 15
RX Data
Bit 1
TX Data
Bit 1
TBR
Empty
Interrupt
Enable
(ETBREI)
Interrupt
Status
Bit (0)
RCVR
FIFO
Reset
Data
Length
Select
Bit 1
(DLS1)
Request
to
Send
(RTS)
Overrun
Error
(OER)
DSR
Toggling
(TDSR)
RX Data
Bit 2
TX Data
Bit 2
USR
Interrupt
Enable
(EUSRI)
Interrupt
Status
Bit (1)
XMIT
FIFO
Reset
Multiple
Stop Bits
Enable
(MSBE)
Loopback
RI
Input
Parity Bit
Error
(PBER)
RI Falling
Edge
(FERI)
RX Data
Bit 3
TX Data
Bit 3
HSR
Interrupt
Enable
(EHSRI)
Interrupt
Status
Bit (2)**
DMA
Mode
Select
Parity
Bit
Enable
(PBE)
IRQ
Enable
No Stop
Bit
Error
(NSER)
DCD
Toggling
(TDCD)
RX Data
Bit 4
TX Data
Bit 4
0 0 0 0
0 0 FIFOs
Reserved Reversed RX
Even
Parity
Enable
(EPE)
Internal
Loopback
Enable
Silent
Byte
Detected
(SBD)
Clear
to Send
(CTS)
RX Data
Bit 5
TX Data
Bit 5
Parity
Bit Fixed
Enable
PBFE)
0 0 0
TBR
Empty
(TBRE)
Data Set
Ready
(DSR)
RX Data
Bit 6
TX Data
Bit 6
Enabled
**
Interrupt
Active Level
(LSB)
Set
Silence
Enable
(SSE)
TSR
Empty
(TSRE)
Ring
Indicator
(RI)
RX Data
Bit 7
TX Data
Bit 7
FIFOs
Enabled
**
RX
Interrupt
Active Level
(MSB)
Baudrate
Divisor
Latch
Access Bit
(BDLAB)
RX FIFO
Error
Indication
(RFEI) **
Data Carrier
Detect
(DCD)
Publication Release Date: March 1998
- 41 - Revision 0.62
Page 50
W83977TF
PRELIMINARY
Bit 4: EPE. This bit describes the number of logic 1's in the data word bits and parity bit only when bit 3 is
programmed. When this bit is set, an even number of logic 1's are sent or checked. When the bit
is reset, an odd number of logic 1's are sent or checked.
Bit 3: PBE. When this bit is set, the position between the last data bit and the stop bit of the SOUT will be
stuffed with the parity bit at the transmitter. For the receiver, the parity bit in the same position as
the transmitter will be detected.
Bit 2: MSBE. This bit defines the number of stop bits in each serial character that is transmitted or
received.
(1) If MSBE is set to a logical 0, one stop bit is sent and checked.
(2) If MSBE is set to a logical 1, and data length is 5 bits, one and a half stop bits are sent and
checked.
(3) If MSBE is set to a logical 1, and data length is 6, 7, or 8 bits, two stop bits are sent and
Bits 0 and 1: DLS0, DLS1. These two bits define the number of data bits that are sent or checked in
TABLE 3-2 WORD LENGTH DEFINITION
checked.
each serial character.
DLS1 DLS0 DATA LENGTH
0 0 5 bits
0 1 6 bits
1 0 7 bits
1 1 8 bits
3.2.2 UART Status Register (USR) (Read/Write)
This 8-bit register provides information about the status of the data transfer during communication.
2
67 0
5
34
1
RBR Data ready (RDR)
Overrun error (OER)
Parity bit error (PBER)
No stop bit error (NSER)
Silent byte detected (SBD)
Transmitter Buffer Register empty (TBRE)
Transmitter Shift Register empty (TSRE)
RX FIFO Error Indication (RFEI)
Bit 7: RFEI. In 16450 mode, this bit is always set to a logic 0. In 16550 mode, this bit is set to a logic 1
when there is at least one parity bit error, no stop bit error or silent byte detected in the FIFO. In
16550 mode, this bit is cleared by reading from the USR if there are no remaining errors left in
the FIFO.
Publication Release Date: March 1998
- 42 - Revision 0.62
Page 51
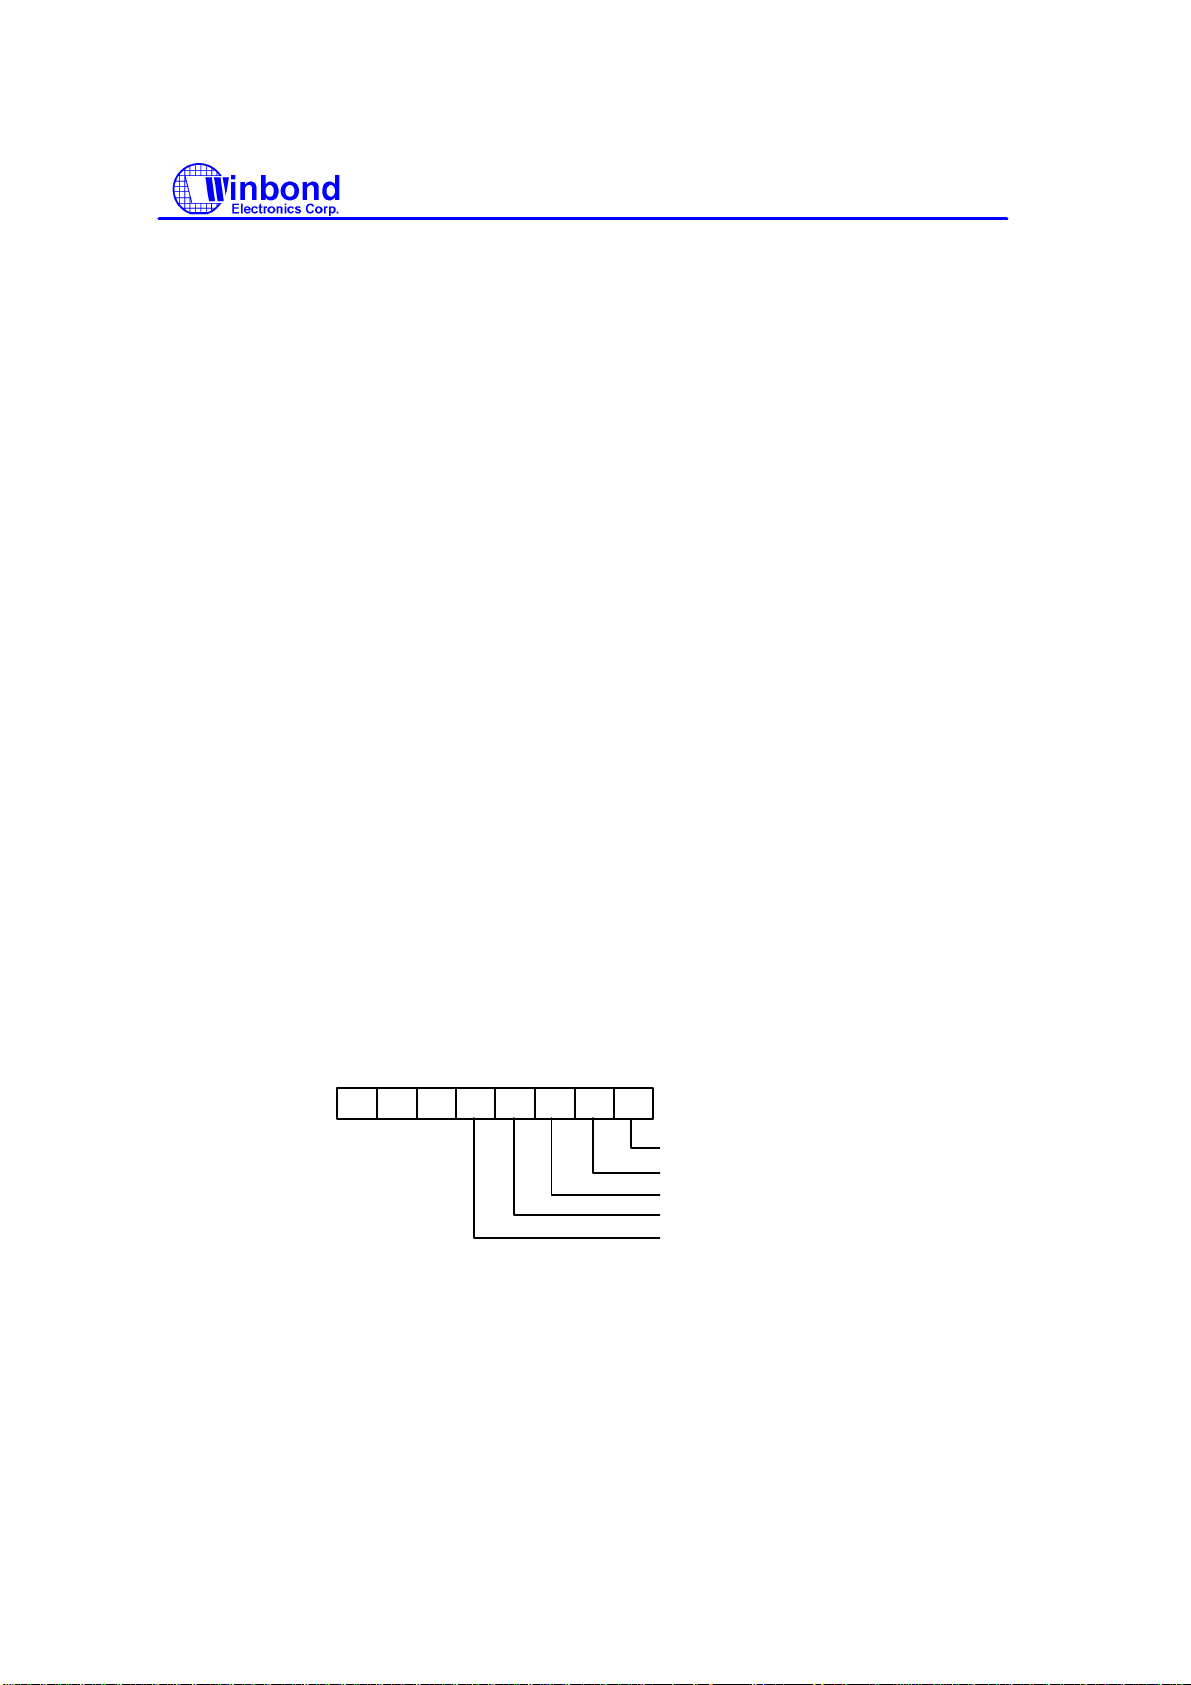
W83977TF
PRELIMINARY
Bit 6: TSRE. In 16450 mode, when TBR and TSR are both empty, this bit will be set to a logical 1. In
16550 mode, if the transmit FIFO and TSR are both empty, it will be set to a logical 1. Other
thanthese two cases, this bit will be reset to a logical 0.
Bit 5: TBRE. In 16450 mode, when a data character is transferred from TBR to TSR, this bit will be set to
a logical 1. If ETREI of ICR is a logical 1, an interrupt will be generated to notify the CPU to write
the next data. In 16550 mode, this bit will be set to a logical 1 when the transmit FIFO is empty. It
will be reset to a logical 0 when the CPU writes data into TBR or FIFO.
Bit 4: SBD. This bit is set to a logical 1 to indicate that received data are kept in silent state for a full word
time, including start bit, data bits, parity bit, and stop bits. In 16550 mode, it indicates the same
condition for the data on top of the FIFO. When the CPU reads USR, it will clear this bit to a
logical 0.
Bit 3: NSER. This bit is set to a logical 1 to indicate that the received data have no stop bit. In 16550
mode, it indicates the same condition for the data on top of the FIFO. When the CPU reads USR,
it will clear this bit to a logical 0.
Bit 2: PBER. This bit is set to a logical 1 to indicate that the parity bit of received data is wrong. In 16550
mode, it indicates the same condition for the data on top of the FIFO. When the CPU reads USR,
it will clear this bit to a logical 0.
Bit 1: OER. This bit is set to a logical 1 to indicate received data have been overwritten by the next
received data before they were read by the CPU. In 16550 mode, it indicates the same condition
instead of FIFO full. When the CPU reads USR, it will clear this bit to a logical 0.
Bit 0: RDR. This bit is set to a logical 1 to indicate received data are ready to be read by the CPU in the
RBR or FIFO. After no data are left in the RBR or FIFO, the bit will be reset to a logical 0.
3.2.3 Handshake Control Register (HCR) (Read/Write)
This register controls the pins of the UART used for handshaking peripherals such as modem, and
controls the diagnostic mode of the UART.
2
7
6
0
00
345
01
Data terminal ready (DTR)
Request to send (RTS)
Loopback RI input
IRQ enable
Internal loopback enable
Publication Release Date: March 1998
- 43 - Revision 0.62
Page 52
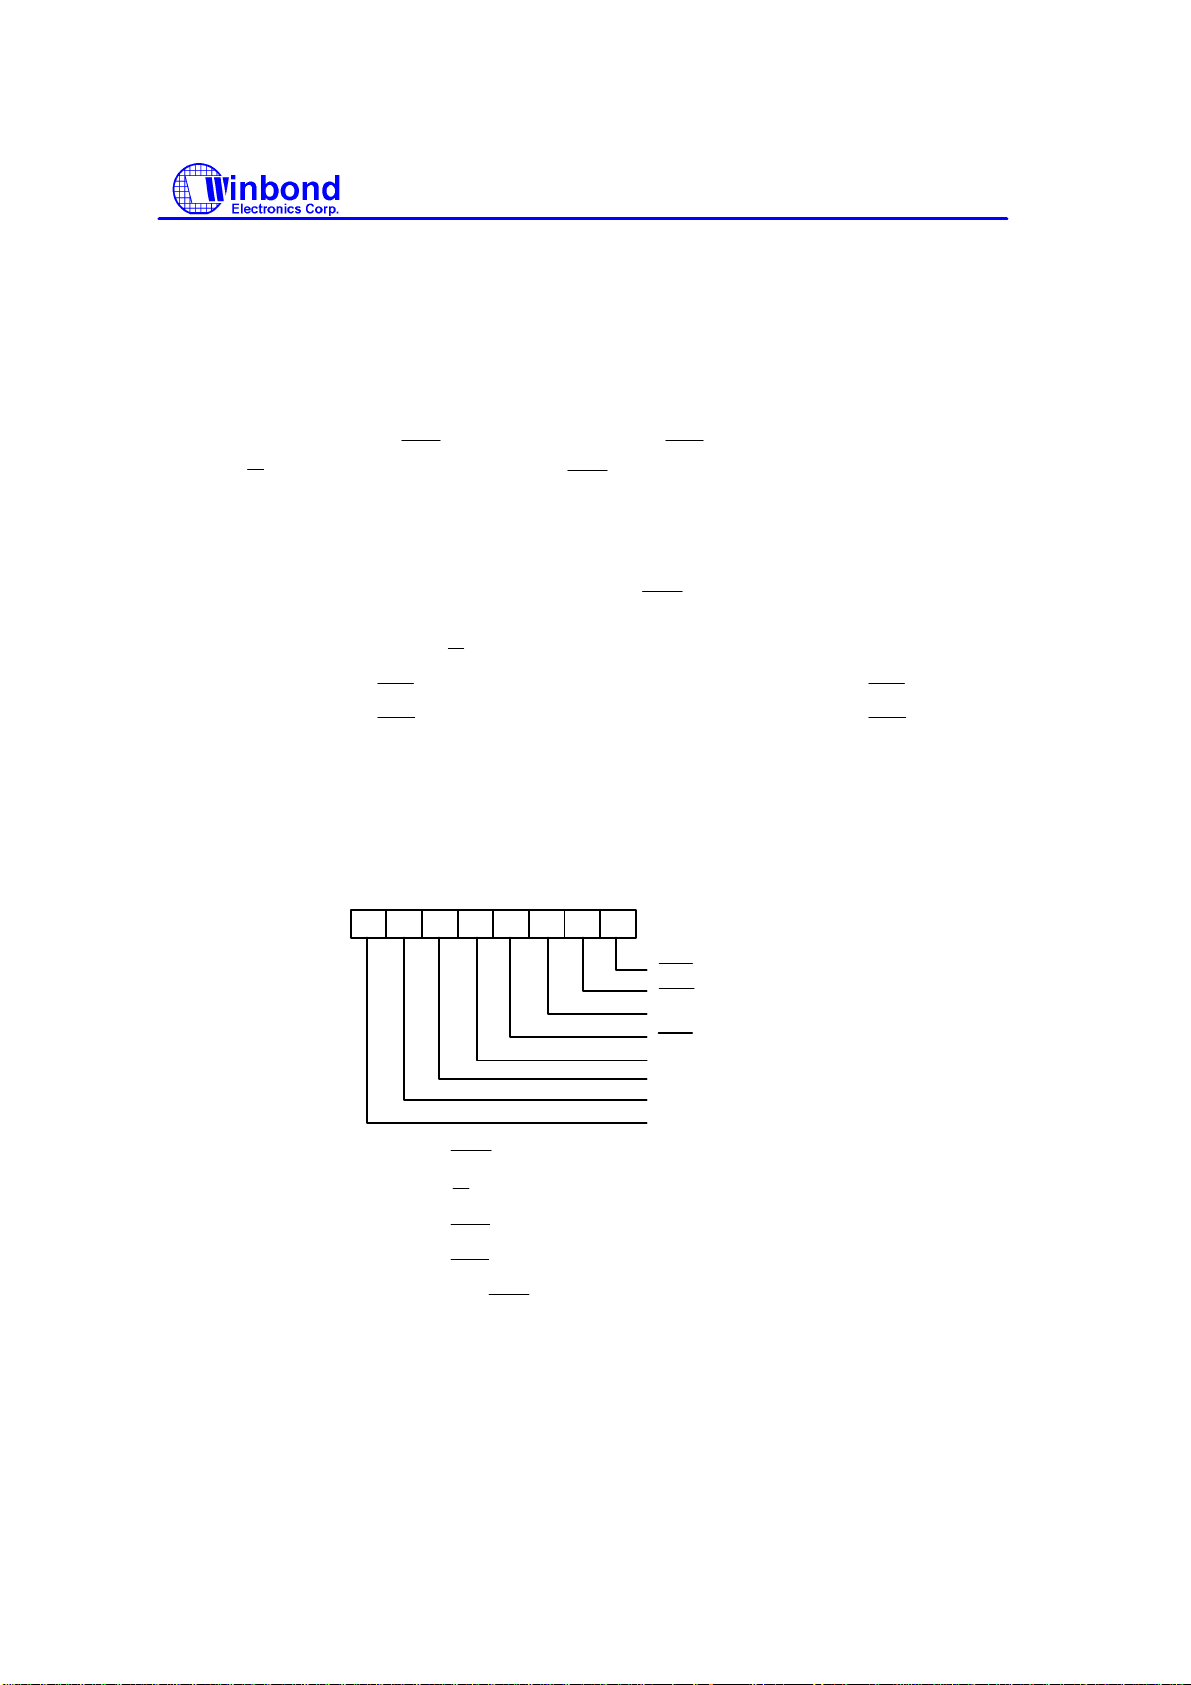
W83977TF
PRELIMINARY
DSR
CTS
DCD
DCD
RTS
RTS
DTR
DTR
DCD
DSR
CTS
DCD
Bit 4: When this bit is set to a logical 1, the UART enters diagnostic mode by an internal loopback, as
follows:
(1) SOUT is forced to logical 1, and SIN is isolated from the communication link instead of the
TSR.
(2) Modem output pins are set to their inactive state.
(3) Modem input pins are isolated from the communication link and connect internally as DTR
(bit 0 of HCR) →
RI and IRQ enable ( bit 3 of HCR) →
Aside from the above connections, the UART operates normally. This method allows the
CPU to test the UART in a convenient way.
Bit 3: The UART interrupt output is enabled by setting this bit to a logic 1. In the diagnostic mode this bit
is internally connected to the modem control input
Bit 2: This bit is used only in the diagnostic mode. In the diagnostic mode this bit is internally connected
to the modem control input RI.
, RTS ( bit 1 of HCR) →
.
, Loopback RI input ( bit 2 of HCR) →
.
Bit 1: This bit controls the
Bit 0: This bit controls the
output. The value of this bit is inverted and output to
output. The value of this bit is inverted and output to
.
.
3.2.4 Handshake Status Register (HSR) (Read/Write)
This register reflects the current state of four input pins for handshake peripherals such as a modem
and records changes on these pins.
1234567 0
toggling (TCTS)
CTS
toggling (TDSR)
DSR
RI falling edge (FERI)
toggling (TDCD)
DCD
Clear to send (CTS)
Data set ready (DSR)
Ring indicator (RI)
Bit 7: This bit is the opposite of the
Data carrier detect (DCD)
input. This bit is equivalent to bit 3 of HCR in loopback mode.
Bit 6: This bit is the opposite of the RI input. This bit is equivalent to bit 2 of HCR in loopback mode.
Bit 5: This bit is the opposite of the
Bit 4: This bit is the opposite of the
input. This bit is equivalent to bit 0 of HCR in loopback mode.
input. This bit is equivalent to bit 1 of HCR in loopback mode.
Bit 3: TDCD. This bit indicates that the
pin has changed state after HSR was read by the CPU.
Publication Release Date: March 1998
- 44 - Revision 0.62
Page 53
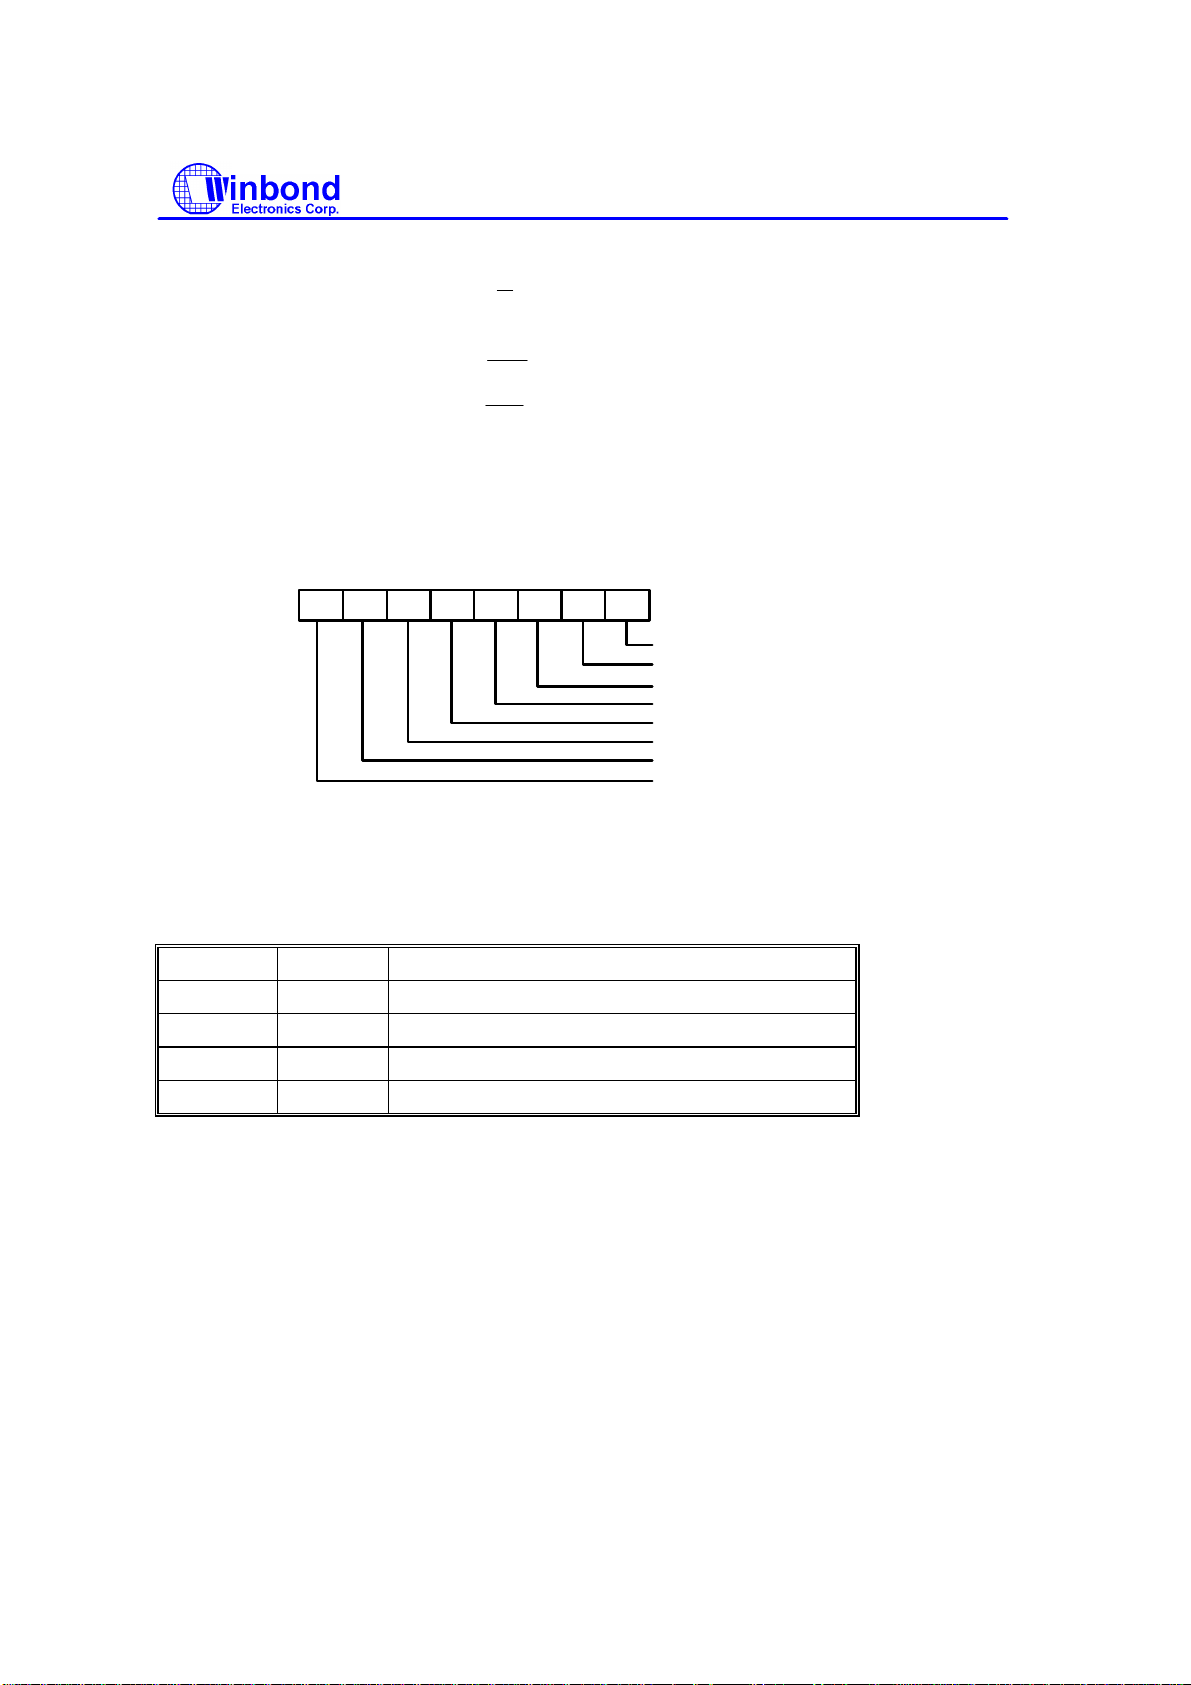
W83977TF
PRELIMINARY
DSR
CTS
Bit 2: FERI. This bit indicates that the RI pin has changed from low to high state after HSR was read
by the CPU.
Bit 1: TDSR. This bit indicates that the
Bit 0: TCTS. This bit indicates that the
3.2.5 UART FIFO Control Register (UFR) (Write only)
This register is used to control the FIFO functions of the UART.
Bit 6, 7: These two bits are used to set the active level for the receiver FIFO interrupt. For example, if the
interrupt active level is set as 4 bytes, once there are more than 4 data characters in the receiver
FIFO, the interrupt will be activated to notify the CPU to read the data from the FIFO.
TABLE 3-3 FIFO TRIGGER LEVEL
pin has changed state after HSR was read by the CPU.
pin has changed state after HSR was read.
34567 0
12
FIFO enable
Receiver FIFO reset
Transmitter FIFO reset
DMA mode select
Reserved
Reserved
RX interrupt active level (LSB)
RX interrupt active level (MSB)
BIT 7 BIT 6 RX FIFO INTERRUPT ACTIVE LEVEL (BYTES)
0 0 01
0 1 04
1 0 08
1 1 14
Bit 4, 5: Reserved
Bit 3: When this bit is programmed to logic 1, the DMA mode will change from mode 0 to mode 1 if
UFR bit 0 = 1.
Bit 2: Setting this bit to a logical 1 resets the TX FIFO counter logic to initial state. This bit will clear to a
logical 0 by itself after being set to a logical 1.
Bit 1: Setting this bit to a logical 1 resets the RX FIFO counter logic to initial state. This bit will clear to a
logical 0 by itself after being set to a logical 1.
Bit 0: This bit enables the 16550 (FIFO) mode of the UART. This bit should be set to a logical 1 before
other bits of UFR are programmed.
Publication Release Date: March 1998
- 45 - Revision 0.62
Page 54
W83977TF
PRELIMINARY
Publication Release Date: March 1998
- 46 - Revision 0.62
Page 55
W83977TF
PRELIMINARY
1
3.2.6 Interrupt Status Register (ISR) (Read only)
This register reflects the UART interrupt status, which is encoded by different interrupt sources into 3
bits.
1234567
0
0 0
0 if interrupt pending
Interrupt Status bit 0
Interrupt Status bit 1
Interrupt Status bit 2
FIFOs enabled
FIFOs enabled
Bit 7, 6: These two bits are set to a logical 1 when UFR bit 0 = 1.
Bit 5, 4: These two bits are always logic 0.
Bit 3: In 16450 mode, this bit is 0. In 16550 mode, both bit 3 and 2 are set to a logical 1 when a time-out
interrupt is pending.
Bit 2, 1: These two bits identify the priority level of the pending interrupt, as shown in the table below.
Bit 0: This bit is a logical 1 if there is no interrupt pending. If one of the interrupt sources has occurred,
this bit will be set to a logical 0.
TABLE 3-4 INTERRUPT CONTROL FUNCTION
ISR INTERRUPT SET AND FUNCTION
Bit 3 Bit 2 Bit 1 Bit 0 Interrupt
priority
0 0 0
0 1 1 0 First UART Receive
0 1 0 0 Second RBR Data Ready 1. RBR data ready
1 1 0 0 Second FIFO Data Timeout Data present in RX FIFO for 4
0 0 1 0 Third TBR Empty TBR empty 1. Write data into TBR
0 0 0 0 Fourth Handshake status 1. TCTS = 1 2. TDSR = 1
** Bit 3 of ISR is enabled when bit 0 of UFR is logical 1.
Interrupt Type
- - No Interrupt pending -
Status
Interrupt Source
1. OER = 1 2. PBER =1
3. NSER = 1 4. SBD = 1
2. FIFO interrupt active level
reached
characters period of time since last
access of RX FIFO.
3. FERI = 1 4. TDCD = 1
Clear Interrupt
Read USR
1. Read RBR
2. Read RBR until FIFO
data under active level
Read RBR
2. Read ISR (if priority is
third)
Read HSR
Publication Release Date: March 1998
- 47 - Revision 0.62
Page 56
W83977TF
PRELIMINARY
UART receive status interrupt enable (EUSRI)
Handshake status interrupt enable (EHSRI)
3.2.7 Interrupt Control Register (ICR) (Read/Write)
This 8-bit register allows the five types of controller interrupts to activate the interrupt output signal
separately. The interrupt system can be totally disabled by resetting bits 0 through 3 of the Interrupt
Control Register (ICR). A selected interrupt can be enabled by setting the appropriate bits of this
register to a logical 1.
7
0
5
6
0 0 0
3
4
2
0
1
RBR data ready interrupt enable (ERDRI)
TBR empty interrupt enable (ETBREI)
Bit 7-4: These four bits are always logic 0.
Bit 3: EHSRI. Setting this bit to a logical 1 enables the handshake status register interrupt.
Bit 2: EUSRI. Setting this bit to a logical 1 enables the UART status register interrupt.
Bit 1: ETBREI. Setting this bit to a logical 1 enables the TBR empty interrupt.
Bit 0: ERDRI. Setting this bit to a logical 1 enables the RBR data ready interrupt.
3.2.8 Programmable Baud Generator (BLL/BHL) (Read/Write)
Two 8-bit registers, BLL and BHL, compose a programmable baud generator that uses 24 MHz to
generate a 1.8461 MHz frequency and divides it by a divisor from 1 to 216-1. The output frequency of
the baud generator is the baud rate multiplied by 16, and this is the base frequency for the transmitter
and receiver. The table in the next page illustrates the use of the baud generator with a frequency of
1.8461 MHz. In high-speed UART mode (refer to CR0C bit7 and CR0C bit6), the programmable baud
generator directly uses 24 MHz and the same divisor as the normal speed divisor. In high-speed mode,
the data transmission rate can be as high as 1.5M bps.
- 48 - Revision 0.62
Publication Release Date: March 1998
Page 57
W83977TF
PRELIMINARY
3.2.9 User-defined Register (UDR) (Read/Write)
This is a temporary register that can be accessed and defined by the user.
TABLE 3-5 BAUD RATE TABLE
BAUD RATE FROM DIFFERENT PRE-DIVIDER
Pre-Div: 13
1.8461M Hz
50 400 650 2304 **
75 600 975 1536 **
110 880 1430 1047 0.18%
134.5 1076 1478.5 857 0.099%
150 1200 1950 768 **
300 2400 3900 384 **
600 4800 7800 192 **
1200 9600 15600 96 **
1800 14400 23400 64 **
2000 16000 26000 58 0.53%
2400 19200 31200 48 **
3600 28800 46800 32 **
4800 38400 62400 24 **
7200 57600 93600 16 **
9600 76800 124800 12 **
19200 153600 249600 6 **
38400 307200 499200 3 **
57600 460800 748800 2 **
115200 921600 1497600 1 **
** The percentage error for all baud rates, except where indicated otherwise, is 0.16%.
Note. Pre-Divisor is determined by CRF0 of UART A and B.
Pre-Div:1.625
14.769M Hz
Pre-Div: 1.0
24M Hz
Decimal divisor used
to generate 16X clock
Error Percentage between
desired and actual
Publication Release Date: March 1998
- 49 - Revision 0.62
Page 58
W83977TF
PRELIMINARY
4. INFRARED (IR) PORT
The Infrared (IR) function provides point-to-point (or multi-point to multi-point) wireless
communication which can operate under various transmission protocols including IrDA 1.0 SIR,
SHARP ASK-IR. IR port shares the same port with UART B port in W83977TF. Please refer to
section 11.5 for configuration information.
5. PARALLEL PORT
5.1 Printer Interface Logic
The parallel port of the W83977TF makes possible the attachment of various devices that accept
eight bits of parallel data at standard TTL level. The W83977TF supports an IBM XT/AT compatible
parallel port (SPP), bi-directional parallel port (BPP), Enhanced Parallel Port (EPP), Extended
Capabilities Parallel Port (ECP), Extension FDD mode (EXTFDD), Extension 2FDD mode
(EXT2FDD) on the parallel port. Refer to the configuration registers for more information on
disabling, power-down, and on selecting the mode of operation.
Table 5-1 shows the pin definitions for different modes of the parallel port.
TABLE 5-1-1
CONNECTOR
Notes:
n<name > : Active Low
1. Compatible Mode
2. High Speed Mode
3. For more information, refer to the IEEE 1284 standard.
PARALLEL PORT CONNECTOR AND PIN DEFINITIONS
HOST
1 36 O nSTB nWrite nSTB, HostClk
2-9 31-26, 24-23 I/O PD<0:7> PD<0:7> PD<0:7>
10 22 I nACK Intr nACK, PeriphClk
11 21 I BUSY nWait BUSY, PeriphAck
12 19 I PE PE PEerror, nAckReverse
13 18 I SLCT Select SLCT, Xflag
14 35 O nAFD nDStrb nAFD, HostAck
15 34 I nERR nError nFault1, nPeriphRequest
16 33 O nINIT nInit nINIT1, nReverseRqst
17 32 O nSLIN nAStrb nSLIN1 , ECPMode
PIN NUMBER
OF W83977TF
PIN
ATTRIBUTE
SPP EPP ECP
2
2
2
2
2
2
2
2
2
Publication Release Date: March 1998
- 49 - Revision 0.62
Page 59
W83977TF
PRELIMINARY
INDEX
2
INDEX
2
TRAK
02
TRAK
02
WP2
WP2
RDATA
2
RDATA
2
DSKCHG
2
DSKCHG
2
MOA2
DSA2
DSB2
DSB2
MOB2
MOB2
WD2
WD2
WE2
WE2
RWC2
RWC2
DIR2
DIR2
STEP
2
STEP
2
TABLE 5-1-2
CONNECTOR
PARALLEL PORT CONNECTOR AND PIN DEFINITIONS
HOST
1 36 O nSTB --- --- --- --2 31 I/O PD0 I
3 30 I/O PD1 I
4 29 I/O PD2 I
5 28 I/O PD3 I
6 27 I/O PD4 I
7 26 I/O PD5 --- --- --- ---
8 24 I/O PD6 OD
9 23 I/O PD7 OD
10 22 I nACK OD
11 21 I BUSY OD
12 19 I PE OD
13 18 I SLCT OD
14 35 O nAFD OD
15 34 I nERR OD
16 33 O nINIT OD
17 32 O nSLIN OD
PIN NUMBER OF
W83977TF
PIN
ATTRIBUTE
SPP PIN
ATTRIBUTE
EXT2FDD PIN
ATTRIBUTE
HEAD2
--- ---
--- ---
OD
OD
OD
OD
OD
OD
OD
OD
EXTFDD
I
I
I
I
I
HEAD2
5.2 Enhanced Parallel Port (EPP)
TABLE 5-2
Notes:
1. These registers are available in all modes.
2. These registers are available only in EPP mode.
- 50 - Revision 0.62
PRINTER MODE AND EPP REGISTER ADDRESS
A2 A1 A0 REGISTER NOTE
0 0 0 Data port (R/W) 1
0 0 1 Printer status buffer (Read) 1
0 1 0 Printer control latch (Write) 1
0 1 0 Printer control swapper (Read) 1
0 1 1 EPP address port (R/W) 2
1 0 0 EPP data port 0 (R/W) 2
1 0 1 EPP data port 1 (R/W) 2
1 1 0 EPP data port 2 (R/W) 2
1 1 1 EPP data port 2 (R/W) 2
Publication Release Date: March 1998
Page 60
W83977TF
PRELIMINARY
BUSY
ACK
BUSY
5.2.1 Data Swapper
The system microprocessor can read the contents of the printer's data latch by reading the data
swapper.
5.2.2 Printer Status Buffer
The system microprocessor can read the printer status by reading the address of the printer status
buffer. The bit definitions are as follows:
1
235 467 0
1 1
TMOUT
ERROR
SLCT
PE
ACK
Bit 7: This signal is active during data entry, when the printer is off-line during printing, when the print
head is changing position, or during an error state. When this signal is active, the printer is
busy and cannot accept data.
Bit 6: This bit represents the current state of the printer's
received a character and is ready to accept another. Normally, this signal will be active for
approximately 5 microseconds before
stops.
Bit 5: Logical 1 means the printer has detected the end of paper.
Bit 4: Logical 1 means the printer is selected.
Bit 3: Logical 0 means the printer has encountered an error condition.
Bit 1, 2: These two bits are not implemented and are logic one during a read of the status register.
Bit 0: This bit is valid in EPP mode only. It indicates that a 10 µS time-out has occurred on the EPP
bus. A logic 0 means that no time-out error has occurred; a logic 1 means that a time-out error
has been detected. Writing a logic 1 to this bit will clear the time-out status bit; writing a logic 0
has no effect.
signal. A 0 means the printer has
Publication Release Date: March 1998
- 51 - Revision 0.62
Page 61
W83977TF
PRELIMINARY
DIR
ACK
5.2.3 Printer Control Latch and Printer Control Swapper
The system microprocessor can read the contents of the printer control latch by reading the printer
control swapper. Bit definitions are as follows:
234567 0
111
STROBE
AUTO FD
INIT
SLCT IN
IRQ ENABLE
Bit 7, 6: These two bits are a logic one during a read. They can be written.
Bit 5: Direction control bit
When this bit is a logic 1, the parallel port is in input mode (read); when it is a logic 0, the
parallel port is in output mode (write). This bit can be read and written. In SPP mode, this bit
is invalid and fixed at zero.
Bit 4: A 1 in this position allows an interrupt to occur when
changes from low to high.
Bit 3: A 1 in this bit position selects the printer.
Bit 2: A 0 starts the printer (50 microsecond pulse, minimum).
Bit 1: A 1 causes the printer to line-feed after a line is printed.
Bit 0: A 0.5 microsecond minimum high active pulse clocks data into the printer. Valid data must be
present for a minimum of 0.5 microseconds before and after the strobe pulse.
5.2.4 EPP Address Port
The address port is available only in EPP mode. Bit definitions are as follows:
1234567 0
PD0
PD1
PD2
PD3
PD4
PD5
PD6
PD7
Publication Release Date: March 1998
- 52 - Revision 0.62
Page 62
W83977TF
PRELIMINARY
IOW
IOW
IOR
IOW
IOW
IOR
BUSY
ACK
ERROR
INIT AUTOFD
STROBE
INIT AUTOFD
STROBE
The contents of DB0-DB7 are buffered (non-inverting) and output to ports PD0-PD7 during a write
operation. The leading edge of
trailing edge of
latches the data for the duration of the EPP write cycle.
c
auses an EPP address write cycle to be performed, and the
PD0-PD7 ports are read during a read operation. The leading edge of
causes an EPP address
read cycle to be performed and the data to be output to the host CPU.
5.2.5 EPP Data Port 0-3
These four registers are available only in EPP mode. Bit definitions of each data port are as follows:
7
123456
0
PD0
PD1
PD2
PD3
PD4
PD5
PD6
PD7
When accesses are made to any EPP data port, the contents of DB0-DB7 are buffered (noninverting) and output to the ports PD0-PD7 during a write operation. The leading edge of
an EPP data write cycle to be performed, and the trailing edge of
duration of the EPP write cycle.
During a read operation, ports PD0-PD7 are read, and the leading edge of
latches the data for the
causes an EPP read
causes
cycle to be performed and the data to be output to the host CPU.
5.2.6 Bit Map of Parallel Port and EPP Registers
REGISTER
Data Port (R/W)
Status Buffer (Read)
Control Swapper (Read)
Control Latch (Write)
EPP Address Port R/W)
EPP Data Port 0 (R/W)
EPP Data Port 1 (R/W)
7 6 5 4 3 2 1 0
PD7 PD6 PD5 PD4 PD3 PD2 PD1 PD0
1 1 1 IRQEN SLIN
1 1 DIR IRQ SLIN
PD7 PD6 PD5 PD4 PD3 PD2 PD1 PD0
PD7 PD6 PD5 PD4 PD3 PD2 PD1 PD0
PD7 PD6 PD5 PD4 PD3 PD2 PD1 PD0
PE SLCT
1 1 TMOUT
Publication Release Date: March 1998
- 53 - Revision 0.62
Page 63
PRELIMINARY
EPP Data Port 2 (R/W)
W83977TF
PD7 PD6 PD5 PD4 PD3 PD2 PD1 PD0
EPP Data Port 3 (R/W)
PD7 PD6 PD5 PD4 PD3 PD2 PD1 PD0
Publication Release Date: March 1998
- 54 - Revision 0.62
Page 64
W83977TF
PRELIMINARY
WAIT
5.2.7 EPP Pin Descriptions
EPP NAME TYPE EPP DESCRIPTION
nWrite O Denotes an address or data read or write operation.
PD<0:7> I/O Bi-directional EPP address and data bus.
Intr I Used by peripheral device to interrupt the host.
nWait I Inactive to acknowledge that data transfer is completed. Active to
indicate that the device is ready for the next transfer.
PE I Paper end; same as SPP mode.
Select I Printer selected status; same as SPP mode.
nDStrb O This signal is active low. It denotes a data read or write operation.
nError I Error; same as SPP mode.
nInits O This signal is active low. When it is active, the EPP device is reset to its
initial operating mode.
nAStrb O This signal is active low. It denotes an address read or write operation.
5.2.8 EPP Operation
When the EPP mode is selected in the configuration register, the standard and bi-directional modes
are also available. The PDx bus is in the standard or bi-directional mode when no EPP read, write, or
address cycle is currently being executed. In this condition all output signals are set by the SPP
Control Port and the direction is controlled by DIR of the Control Port.
A watchdog timer is required to prevent system lockup. The timer indicates that more than 10 µS
have elapsed from the start of the EPP cycle to the time
is aborted when a time-out occurs. The time-out condition is indicated in Status bit 0.
5.2.8.1 EPP Operation
The EPP operates on a two-phase cycle. First, the host selects the register within the device for
subsequent operations. Second, the host performs a series of read and/or write byte operations to the
selected register. Four operations are supported on the EPP: Address Write, Data Write, Address
Read, and Data Read. All operations on the EPP device are performed asynchronously.
5.2.8.2 EPP Version 1.9 Operation
The EPP read/write operation can be completed under the following conditions:
a. If the nWait is active low, when the read cycle (nWrite inactive high, nDStrb/nAStrb active low) or
write cycle (nWrite active low, nDStrb/nAStrb active low) starts, the read/write cycle proceeds
normally and will be completed when nWait goes inactive high.
b. If nWait is inactive high, the read/write cycle will not start. It must wait until nWait changes to
active low, at which time it will start as described above.
5.2.8.3 EPP Version 1.7 Operation
The EPP read/write cycle can start without checking whether nWait is active or inactive. Once the
read/write cycle starts, however, it will not terminate until nWait changes from active low to inactive
high.
is deasserted. The current EPP cycle
Publication Release Date: March 1998
- 55 - Revision 0.62
Page 65
W83977TF
PRELIMINARY
5.3 Extended Capabilities Parallel (ECP) Port
This
port is software and hardware compatible with existing parallel ports, so it may be used as a
standard printer mode if ECP is not required. It provides an automatic high burst-bandwidth channel
that supports DMA for ECP in both the forward (host to peripheral) and reverse (peripheral to host)
directions.
Small FIFOs are used in both forward and reverse directions to improve the maximum bandwidth
requirement. The size of the FIFO is 16 bytes. The ECP port supports an automatic handshake for
the standard parallel port to improve compatibility mode transfer speed.
The ECP port supports run-length-encoded (RLE) decompression (required) in hardware.
Compression is accomplished by counting identical bytes and transmitting an RLE byte that indicates
how many times the next byte is to be repeated. Hardware support for compression is optional.
For more information about the ECP Protocol, refer to the Extended Capabilities Port Protocol and
ISA Interface Standard.
5.3.1 ECP Register and Mode Definitions
NAME ADDRESS I/O ECP MODES FUNCTION
data Base+000h R/W 000-001 Data Register
ecpAFifo Base+000h R/W 011 ECP FIFO (Address)
dsr Base+001h R All Status Register
dcr Base+002h R/W All Control Register
cFifo Base+400h R/W 010 Parallel Port Data FIFO
ecpDFifo Base+400h R/W 011 ECP FIFO (DATA)
tFifo Base+400h R/W 110 Test FIFO
cnfgA Base+400h R 111 Configuration Register A
cnfgB Base+401h R/W 111 Configuration Register B
ecr Base+402h R/W All Extended Control Register
Note: The base addresses are specified by CR60 and 61, which are determined by configuration register or hardware setting.
MODE DESCRIPTION
000 SPP mode
001 PS/2 Parallel Port mode
010 Parallel Port Data FIFO mode
011 ECP Parallel Port mode
100 EPP mode (If this option is enabled in the CRF0 to select ECP/EPP mode)
101 Reserved
110 Test mode
111 Configuration mode
Note: The mode selection bits are bit 7-5 of the Extended Control Register.
Publication Release Date: March 1998
- 56 - Revision 0.62
Page 66
W83977TF
PRELIMINARY
PD7
Address or RLE
5.3.2 Data and ecpAFifo Port
Modes 000 (SPP) and 001 (PS/2) (Data Port)
During a write operation, the Data Register latches the contents of the data bus on the rising edge of
the input. The contents of this register are output to the PD0-PD7 ports. During a read operation,
ports PD0-PD7 are read and output to the host. The bit definitions are as follows:
7 6 5 4 3 2 1 0
PD0
PD1
PD2
PD3
PD4
PD5
PD6
Mode 011 (ECP FIFO-Address/RLE)
A data byte written to this address is placed in the FIFO and tagged as an ECP Address/RLE. The
hardware at the ECP port transmits this byte to the peripheral automatically. The operation of this
register is defined only for the forward direction. The bit definitions are as follows:
7 6 5 4 3 2 1 0
Address/RLE
5.3.3 Device Status Register (DSR)
These bits are at low level during a read of the Printer Status Register. The bits of this status register
are defined as follows:
7 6 5 4 3 2 1 0
11 1
nFault
Select
PError
nAck
nBusy
Publication Release Date: March 1998
- 57 - Revision 0.62
Page 67
W83977TF
PRELIMINARY
ACK
SLIN
INIT
AFD
STB
Bit 7: This bit reflects the complement of the Busy input.
Bit 6: This bit reflects the nAck input.
Bit 5: This bit reflects the PError input.
Bit 4: This bit reflects the Select input.
Bit 3: This bit reflects the nFault input.
Bit 2-0: These three bits are not implemented and are always logic one during a read.
5.3.4 Device Control Register (DCR)
The bit definitions are as follows:
7 6 5 4 3 2 1 0
1 1
strobe
autofd
nInit
SelectIn
ackIntEn
Direction
Bit 6, 7: These two bits are logic one during a read and cannot be written.
Bit 5: This bit has no effect and the direction is always out if mode = 000 or mode = 010. Direction is
valid in all other modes.
0 the parallel port is in output mode.
1 the parallel port is in input mode.
Bit 4: Interrupt request enable. When this bit is set to a high level, it may be used to enable interrupt
requests from the parallel port to the CPU due to a low to high transition on the
Bit 3: This bit is inverted and output to the
output.
input.
0 The printer is not selected.
1 The printer is selected.
Bit 2: This bit is output to the
Bit 1: This bit is inverted and output to the
Bit 0: This bit is inverted and output to the
output.
output.
output.
Publication Release Date: March 1998
- 58 - Revision 0.62
Page 68
W83977TF
PRELIMINARY
compress
5.3.5 cFifo (Parallel Port Data FIFO) Mode = 010
This mode is defined only for the forward direction. The standard parallel port protocol is used by a
hardware handshake to the peripheral to transmit bytes written or DMAed from the system to this
FIFO. Transfers to the FIFO are byte aligned.
5.3.6 ecpDFifo (ECP Data FIFO) Mode = 011
When the direction bit is 0, bytes written or DMAed from the system to this FIFO are transmitted by a
hardware handshake to the peripheral using the ECP parallel port protocol. Transfers to the FIFO are
byte aligned.
When the direction bit is 1, data bytes from the peripheral are read under automatic hardware
handshake from ECP into this FIFO. Reads or DMAs from the FIFO will return bytes of ECP data to
the system.
5.3.7 tFifo (Test FIFO Mode) Mode = 110
Data bytes may be read, written, or DMAed to or from the system to this FIFO in any direction. Data
in the tFIFO will not be transmitted to the parallel port lines. However, data in the tFIFO may be
displayed on the parallel port data lines.
5.3.8 cnfgA (Configuration Register A) Mode = 111
This register is a read-only register. When it is read, 10H is returned. This indicates to the system that
this is an 8-bit implementation.
5.3.9 cnfgB (Configuration Register B) Mode = 111
The bit definitions are as follows:
7 6 5 4 3 2 1 0
1 1 1
IRQx 0
IRQx 1
IRQx 2
intrValue
Bit 7: This bit is read-only. It is at low level during a read. This means that this chip does not support
hardware RLE compression.
Bit 6: Returns the value on the ISA IRQ line to determine possible conflicts.
Publication Release Date: March 1998
- 59 - Revision 0.62
Page 69
W83977TF
PRELIMINARY
Bit 5-3: Reflect the IRQ resource assigned for ECP port.
cnfgB[5:3] IRQ resource
000 reflect other IRQ resources selected by PnP register (default)
001 IRQ7
010 IRQ9
011 IRQ10
100 IRQ11
101 IRQ14
110 IRQ15
Bit 2-0: These five bits are at high level during a read and can be written
5.3.10 ecr (Extended Control Register) Mode = all
This register controls the extended ECP parallel port functions. The bit definitions are follows:
Bit 7-5: These bits are read/write and select the mode.
111 IRQ5
.
7 6 5 4 3 2 1 0
empty
full
service Intr
dmaEn
nErrIntrEn
MODE
MODE
MODE
000 Standard Parallel Port mode. The FIFO is reset in this mode.
001 PS/2 Parallel Port mode. This is the same as 000 except that direction may be
used to tri-state the data lines and reading the data register returns the value on the
data lines and not the value in the data register.
010 Parallel Port FIFO mode. This is the same as 000 except that bytes are written or
DMAed to the FIFO. FIFO data are automatically transmitted using the standard
parallel port protocol. This mode is useful only when direction is 0.
011 ECP Parallel Port Mode. When the direction is 0 (forward direction), bytes placed
into the ecpDFifo and bytes written to the ecpAFifo are placed in a single FIFO and
auto transmitted to the peripheral using ECP Protocol. When the direction is 1
(reverse direction), bytes are moved from the ECP parallel port and packed into
bytes in the ecpDFifo.
100 Selects EPP Mode. In this mode, EPP is activated if the EPP mode is selected.
101 Reserved.
110 Test Mode. The FIFO may be written and read in this mode, but the data will not be
transmitted on the parallel port.
111 Configuration Mode. The confgA and confgB registers are accessible at 0x400 and
0x401 in this mode.
Publication Release Date: March 1998
- 60 - Revision 0.62
Page 70
PRELIMINARY
Bit 4: Read/Write (Valid only in ECP Mode)
1 Disables the interrupt generated on the asserting edge of nFault.
0 Enables an interrupt pulse on the high to low edge of nFault. If nFault is asserted
(interrupt) an interrupt will be generated and this bit is written from a 1 to 0.
Bit 3: Read/Write
1 Enables DMA.
0 Disables DMA unconditionally.
Bit 2: Read/Write
1 Disables DMA and all of the service interrupts.
0 Enables one of the following cases of interrupts. When one of the service interrupts
has occurred, the serviceIntr bit is set to a 1 by hardware. This bit must be reset to
0 to re-enable the interrupts. Writing a 1 to this bit will not cause an interrupt.
(a) dmaEn = 1: During DMA this bit is set to a 1 when terminal count is reached.
(b) dmaEn = 0 direction = 0: This bit is set to 1 whenever there are writeIntr
Threshold or more bytes free in the FIFO.
(c) dmaEn = 0 direction = 1: This bit is set to 1 whenever there are readIntr
Threshold or more valid bytes to be read from the FIFO.
Bit 1: Read only
0 The FIFO has at least 1 free byte.
1 The FIFO cannot accept another byte or the FIFO is completely full.
Bit 0: Read only
0 The FIFO contains at least 1 byte of data.
1 The FIFO is completely empty.
W83977TF
5.3.11 Bit Map of ECP Port Registers
D7 D6 D5 D4 D3 D2 D1 D0 NOTE
data
ecpAFifo
dsr
dcr
cFifo
ecpDFifo
tFifo
cnfgA
cnfgB
ecr
Notes:
1. These registers are available in all modes.
2. All FIFOs use one common 16-byte FIFO.
PD7 PD6 PD5 PD4 PD3 PD2 PD1 PD0
Addr/RLE Address or RLE field 2
nBusy nAck PError Select nFault 1 1 1 1
1 1 Directio ackIntEn SelectIn nInit autofd strobe 1
Parallel Port Data FIFO 2
ECP Data FIFO 2
Test FIFO 2
0 0 0 1 0 0 0 0
compress intrValue 1 1 1 1 1 1
MODE nErrIntrEn dmaEn serviceIntr full empty
Publication Release Date: March 1998
- 61 - Revision 0.62
Page 71
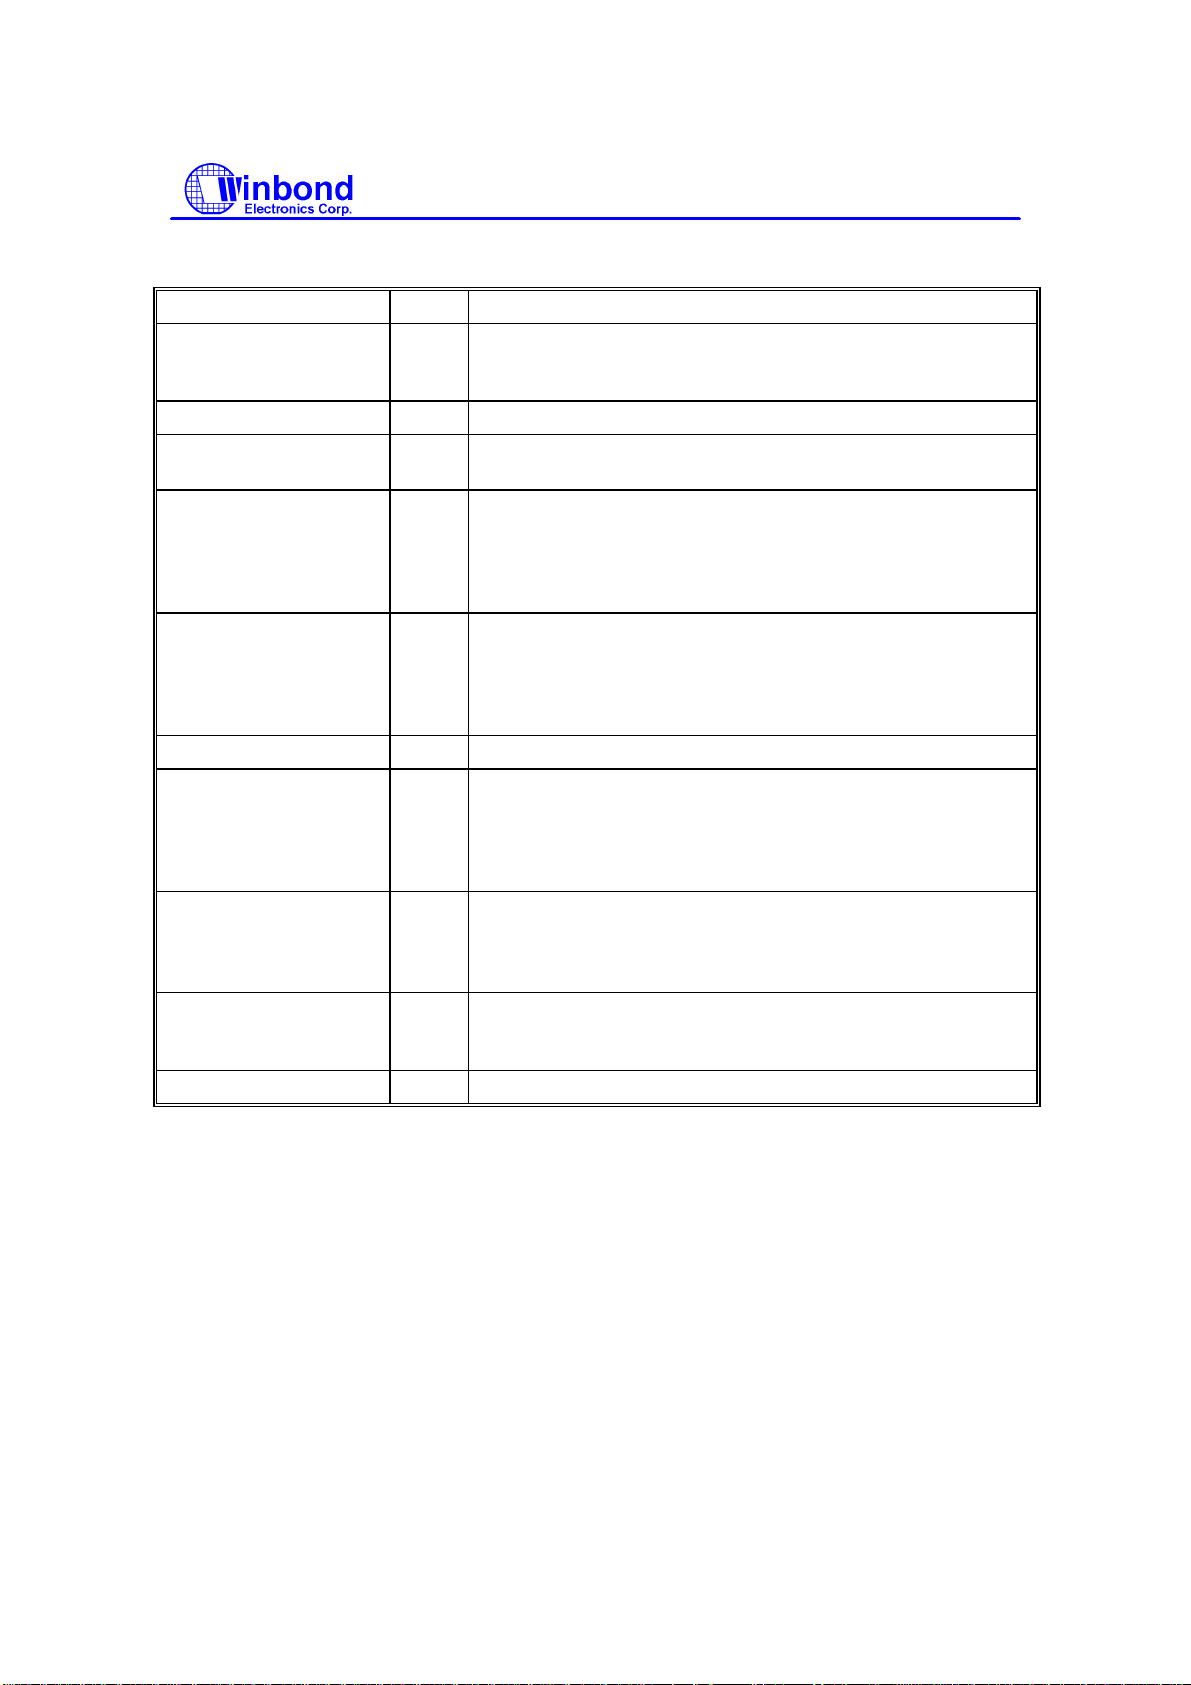
W83977TF
PRELIMINARY
5.3.12 ECP Pin Descriptions
NAME TYPE DESCRIPTION
nStrobe (HostClk) O The nStrobe registers data or address into the slave on the
asserting edge during write operations. This signal handshakes
with Busy.
PD<7:0> I/O These signals contains address or data or RLE data.
nAck (PeriphClk) I This signal indicates valid data driven by the peripheral when
asserted. This signal handshakes with nAutoFd in reverse.
Busy (PeriphAck) I This signal deasserts to indicate that the peripheral can accept
data. It indicates whether the data lines contain ECP command
information or data in the reverse direction. When in reverse
direction, normal data are transferred when Busy (PeriphAck)
is high and an 8-bit command is transferred when it is low.
PError (nAckReverse) I This signal is used to acknowledge a change in the direction of
the transfer (asserted = forward). The peripheral drives this
signal low to acknowledge nReverseRequest. The host relies
upon nAckReverse to determine when it is permitted to drive
the data bus.
Select (Xflag) I Indicates printer on line.
nAutoFd (HostAck) O Requests a byte of data from the peripheral when it is asserted.
This signal indicates whether the data lines contain ECP
address or data in the forward direction. When in forward
direction, normal data are transferred when nAutoFd (HostAck)
is high and an 8-bit command is transferred when it is low.
nFault (nPeriphRequest) I Generates an error interrupt when it is asserted. This signal is
valid only in the forward direction. The peripheral is permitted
(but not required) to drive this pin low to request a reverse
transfer during ECP Mode.
nInit (nReverseRequest) O This signal sets the transfer direction (asserted = reverse,
deasserted = forward). This pin is driven low to place the
channel in the reverse direction.
nSelectIn (ECPMode) O This signal is always deasserted in ECP mode.
Publication Release Date: March 1998
- 62 - Revision 0.62
Page 72
W83977TF
PRELIMINARY
5.3.13 ECP Operation
The host must negotiate on the parallel port to determine if the peripheral supports the ECP protocol
before ECP operation. After negotiation, it is necessary to initialize some of the port bits. The
following are required:
(a) Set direction = 0, enabling the drivers.
(b) Set strobe = 0, causing the nStrobe signal to default to the deasserted state.
(c) Set autoFd = 0, causing the nAutoFd signal to default to the deasserted state.
(d) Set mode = 011 (ECP Mode)
ECP address/RLE bytes or data bytes may be sent automatically by writing the ecpAFifo or ecpDFifo,
respectively.
5.3.13.1 Mode Switching
Software will execute P1284 negotiation and all operations prior to a data transfer phase under
programmed I/O control (mode 000 or 001). Hardware provides an automatic control line handshake,
moving data between the FIFO and the ECP port only in the data transfer phase (mode 011 or 010).
If the port is in mode 000 or 001 it may switch to any other mode. If the port is not in mode 000 or 001
it can only be switched into mode 000 or 001. The direction can be changed only in mode 001.
When in extended forward mode, the software should wait for the FIFO to be empty before switching
back to mode 000 or 001. In ECP reverse mode the software waits for all the data to be read from the
FIFO before changing back to mode 000 or 001.
5.3.13.2 Command/Data
ECP mode allows the transfer of normal 8-bit data or 8-bit commands. In the forward direction,
normal data are transferred when HostAck is high and an 8-bit command is transferred when HostAck
is low. The most significant bits of the command indicate whether it is a run-length count (for
compression) or a channel address.
In the reverse direction, normal data are transferred when PeriphAck is high and an 8-bit command is
transferred when PeriphAck is low. The most significant bit of the command is always zero.
5.3.13.3 Data Compression
The W83977TF supports run length encoded (RLE) decompression in hardware and can transfer
compressed data to a peripheral. Note that the odd (RLE) compression in hardware is not supported.
In order to transfer data in ECP mode, the compression count is written to the ecpAFifo and the data
byte is written to the ecpDFifo.
5.3.14 FIFO Operation
The FIFO threshold is set in configuration register 5. All data transfers to or from the parallel port can
proceed in DMA or Programmed I/O (non-DMA) mode, as indicated by the selected mode. The FIFO
is used by selecting the Parallel Port FIFO mode or ECP Parallel Port Mode. After a reset, the FIFO
is disabled.
Publication Release Date: March 1998
- 63 - Revision 0.62
Page 73
W83977TF
PRELIMINARY
MOB
DSB
DSKCHG
RDATA
TRAK
0
INDEX
MOA
DSA, MOB
DSB
DSKCHG
RDATA
TRAK
0
INDEX
5.3.15 DMA Transfers
DMA transfers are always to or from the ecpDFifo, tFifo, or CFifo. The DMA uses the standard PC
DMA services. The ECP requests DMA transfers from the host by activating the PDRQ pin. The DMA
will empty or fill the FIFO using the appropriate direction and mode. When the terminal count in the
DMA controller is reached, an interrupt is generated and serviceIntr is asserted, which will disable the
DMA.
5.3.16 Programmed I/O (NON-DMA) Mode
The ECP or parallel port FIFOs can also be operated using interrupt driven programmed I/O.
Programmed I/O transfers are to the ecpDFifo at 400H and ecpAFifo at 000H or from the ecpDFifo
located at 400H, or to/from the tFifo at 400H. The host must set the direction, state, dmaEn = 0 and
serviceIntr = 0 in the programmed I/O transfers.
The ECP requests programmed I/O transfers from the host by activating the IRQ pin. The
programmed I/O will empty or fill the FIFO using the appropriate direction and mode.
5.4 Extension FDD Mode (EXTFDD)
In this mode, the W83977TF changes the printer interface pins to FDC input/output pins, allowing the
user to install a second floppy disk drive (FDD B) through the DB-25 printer connector. The pin
assignments for the FDC input/output pins are shown in Table 5-1.
After the printer interface is set to EXTFDD mode, the following occur:
(1) Pins
(2) Pins
as input signals to the FDC.
(3) Pins PD4-PD0 each will have an internal resistor of about 1K ohm to serve as pull-up resistor for
FDD open drain/collector output.
(4) If the parallel port is set to EXTFDD mode after the system has booted DOS or another operating
system, a warm reset is needed to enable the system to recognize the extension floppy drive.
and
will be forced to inactive state.
,
, WP,
,
will be logically ORed with pins PD4-PD0 to serve
5.5 Extension 2FDD Mode (EXT2FDD)
In this mode, the W83977TF changes the printer interface pins to FDC input/output pins, allowing the
user to install two external floppy disk drives through the DB-25 printer connector to replace internal
floppy disk drives A and B. The pin assignments for the FDC input/output pins are shown in Table5-1.
After the printer interface is set to EXTFDD mode, the following occur:
(1) Pins
(2) Pins
serve as input signals to the FDC.
(3) Pins PD4-PD0 each will have an internal resistor of about 1K ohm to serve as pull-up resistor for
FDD open drain/collector output.
(4) If the parallel port is set to EXT2FDD mode after the system has booted DOS or another operating
system, a warm reset is needed to enable the system to recognize the extension floppy drive.
- 64 - Revision 0.62
,
,
, and
, WP,
will be forced to inactive state.
, and
will be logically ORed with pins PD4-PD0 to
Publication Release Date: March 1998
Page 74
PRELIMINARY
6. KEYBOARD CONTROLLER
W83977TF
The KBC (8042 with licensed KB BIOS) circuit of W83977TF is designed to provide the functions
needed to interface a CPU with a keyboard and/or a PS/2 mouse, and can be used with IBM
-
compatible personal computers or PS/2-based systems. The controller receives serial data from the
keyboard or PS/2 mouse, checks the parity of the data, and presents the data to the system as a byte
of data in its output buffer. Then, the controller will assert an interrupt to the system when data are
placed in its output buffer. The keyboard and PS/2 mouse are required to acknowledge all data
transmissions. No transmission should be sent to the keyboard or PS/2 mouse until an acknowledge
is received for the previous data byte.
GP I/O PINS
Multiplex I/O PINS
P17KINH
P12~P16
8042
P24
P25
P21
P20
P27
P10
P26
T0
P23
T1
P22
P11
KIRQ
MIRQ
GATEA20
KBRST
KDAT
KCLK
MCLK
MDAT
Keyboard and Mouse Interface
6.1 Output Buffer
The output buffer is an 8-bit read-only register at I/O address 60H (Default, PnP programmable I/O
address LD5-CR60 and LD5-CR61). The keyboard controller uses the output buffer to send the scan
code received from the keyboard and data bytes required by commands to the system. The output
buffer can only be read when the output buffer full bit in the register is "1".
6.2 Input Buffer
The input buffer is an 8-bit write-only register at I/O address 60H or 64H (Default, PnP programmable
I/O address LD5-CR60, LD5-CR61, LD5-CR62, and LD5-CR63). Writing to address 60H sets a flag
to indicate a data write; writing to address 64H sets a flag to indicate a command write. Data written
to I/O address 60H is sent to keyboard (unless the keyboard controller is expecting a data byte)
through the controller's input buffer only if the input buffer full bit in the status register is 0 .
Publication Release Date: March 1998
- 65 - Revision 0.62
Page 75
W83977TF
PRELIMINARY
6.3 Status Register
The status register is an 8-bit read-only register at I/O address 64H (Default, PnP programmable I/O
address LD5-CR62 and LD5-CR63), that holds information about the status of the keyboard controller
and interface. It may be read at any time.
BIT BIT FUNCTION DESCRIPTION
0 Output Buffer Full 0: Output buffer empty
1: Output buffer full
1 Input Buffer Full 0: Input buffer empty
1: Input buffer full
2 System Flag This bit may be set to 0 or 1 by writing to the system flag
bit in the command byte of the keyboard controller. It
defaults to 0 after a power-on reset.
3 Command/Data 0: Data byte
1: Command byte
4 Inhibit Switch 0: Keyboard is inhibited
1: Keyboard is not inhibited
5 Auxiliary Device Output
Buffer
6 General Purpose Time-
out
7 Parity Error 0: Odd parity
0: Auxiliary device output buffer empty
1: Auxiliary device output buffer full
0: No time-out error
1: Time-out error
1: Even parity (error)
6.4 Commands
COMMAND FUNCTION
20h Read Command Byte of Keyboard Controller
60h Write Command Byte of Keyboard Controller
A4h Test Password
BIT
Reserved
7
6
IBM Keyboard Translate Mode
Disable Auxiliary Device
5
4
Disable Keyboard
3
Reserve
System Flag
2
1
Enable Auxiliary Interrupt
0
Enable Keyboard Interrupt
BIT DEFINITION
Returns 0Fah if Password is loaded
Returns 0F1h if Password is not loaded
Publication Release Date: March 1998
- 66 - Revision 0.62
Page 76
PRELIMINARY
6.4 Commands, continued
COMMAND FUNCTION
A5h Load Password
A6h Enable Password
A7h Disable Auxiliary Device Interface
A8h Enable Auxiliary Device Interface
A9h Interface Test
AAh Self-test
ABh Interface Test
ADh Disable Keyboard Interface
AEh Enable Keyboard Interface
C0h Read Input Port(P1) and send data to the system
C1h Continuously puts the lower four bits of Port1 into STATUS register
C2h Continuously puts the upper four bits of Port1 into STATUS register
D0h Send Port2 value to the system
D1h Only set/reset GateA20 line based on the system data bit 1
D2h Send data back to the system as if it came from Keyboard
D3h Send data back to the system as if it came from Auxiliary Device
D4h Output next received byte of data from system to Auxiliary Device
E0h Reports the status of the test inputs
FXh
W83977TF
Load Password until a "0" is received from the system
Enable the checking of keystrokes for a match with the password
BIT
No Error Detected
00
01
Auxiliary Device "Clock" line is stuck low
Auxiliary Device "Clock" line is stuck high
02
03
Auxiliary Device "Data" line is stuck low
04
Auxiliary Device "Data" line is stuck low
Returns 055h if self test succeeds
BIT
00
01
02
03
04
Pulse only RC(the reset line) low for 6µS if Command byte is even
BIT DEFINITION
BIT DEFINITION
No Error Detected
Keyboard "Clock" line is stuck low
Keyboard "Clock" line is stuck high
Keyboard "Data" line is stuck low
Keyboard "Data" line is stuck high
Publication Release Date: March 1998
- 67 - Revision 0.62
Page 77
W83977TF
PRELIMINARY
6.5 Hardware GATEA20/Keyboard Reset Control Logic
The KBC implements a hardware control logic to speed-up GATEA20 and KBRESET. This control
logic is controlled by LD5-CRF0 as follows:
6.5.1 KB Control Register (Logic Device 5, CR-F0)
BIT 7 6 5 4 3 2 1 0
NAME KCLKS1 KCLKS0 Reserved Reserved Reserved P92EN HGA20 HKBRST
KCLKS1, KCLKS0
This 2 bits are for the KBC clock rate selection.
= 0 0 KBC clock input is 6 Mhz
= 0 1 KBC clock input is 8 Mhz
= 1 0 KBC clock input is 12 Mhz
= 1 1 KBC clock input is 16 Mhz
P92EN
A "1" on this bit enables Port 92 to control GATEA20 and KBRESET.
A "0" on this bit disables Port 92 functions.
HGA20
A "1" on this bit selects hardware GATEA20 control logic to control GATE A20 signal.
A "0" on this bit disables hardware GATEA20 control logic function.
HKBRST
A "1" on this bit selects hardware KB RESET control logic to control KBRESET signal.
A "0" on this bit disables hardware KB RESET control logic function.
When the KBC receives data that follows a "D1" command, the hardware control logic sets or clears
GATE A20 according to the received data bit 1. Similarly, the hardware control logic sets or clears
KBRESET depending on the received data bit 0. When the KBC receives a "FE" command, the
KBRESET is pulse low for 6µS(Min.) with 14µS(Min.) delay.
GATEA20 and KBRESET are controlled by either the software control or the hardware control logic
and they are mutually exclusive. Then, GATEA20 and KBRESET are merged along with Port92
when P92EN bit is set.
(Port 92 Enable)
(Hardware GATE A20)
(Hardware Keyboard Reset)
6.5.2 Port 92 Control Register (Default Value = 0x24)
BIT 7 6 5 4 3 2 1 0
NAME Res. (0) Res. (0) Res. (1) Res. (0) Res. (0) Res. (1) SGA20 PLKBRST
SGA20
A "1" on this bit drives GATE A20 signal to high.
A "0" on this bit drives GATE A20 signal to low.
PLKBRST
A "1" on this bit causes KBRESET to drive low for 6µS(Min.) with 14µS(Min.) delay. Before issuing
another keyboard reset command, the bit must be cleared.
- 68 - Revision 0.62
(Special GATE A20 Control)
(Pull-Low KBRESET)
Publication Release Date: March 1998
Page 78
W83977TF
PRELIMINARY
PANSWOUT
PANSWIN
PANSWIN
PANSWOUT
6.6 OnNow / Security Keyboard and Mouse Wake-Up
---- Programmable Keyboard / Mouse Wake-Up Functions
Winbond's unique programmable keyboard/ mouse wake-up functions provide the system diversified
methods for either OnNow wake-up application, or security control application. The keyboard or
mouse can wake up the system by producing a panel switch low pulse on
it to chipset (for example IntelTM chipset TX, LX PIIX4) panel switch input. The wake-up conditions
can be programmed as pre-determined or any keys/buttons. To implement this function, a
32.768KHz crystal must be installed between XTAL1 and XTAL2, or a 32.768KHz clock to be
connected to XTAL1 and leave XTAL2 open. The VSB pin must be connected to +5V VSB of ATX
power supply, and an external battery should be installed on V
passwords and wake-up status which had been set already) when power fails.
6.6.1 Keyboard Wake-Up Function
The keyboard wake-up function is enable by setting LD-0A CR-E0 bit 6. The pre-determined keys
data are stored in registers, and they can be access by an indirection method. At first, write their
index address to LD-0A CR-E1, then access them by reading/writing LD-0A CR-E2. A zero data is
written to the register means the comparison of this register will be ignored. The pre-programmed
keys may be 1 to 5 keys with various combinations. If LD-0A CR-E0 bit 0 is set, the system will be
waken up after any key struck.
6.6.2 Keyboard Password Wake-Up Function
To implement this function, the bit 7 of LD-0A CR-E0 must be set, and panel switch input is
connected to
and make only keyboard can wake up the system with preset keys (password).
pin. Thus
is blocked to
BAT
pin to store the data (the
, by setting LD-0A CR-E0 properly
pin, and connect
6.6.3 Mouse Wake-Up Function
The mouse wake-up function is activated by setting bit 5 of LD-0A CR-E0. If bit 1 of LD-0A CR-E0 is
set, any movement or button clicking will make up the system. Otherwise, the mouse can wake up
the system only by clicking its button twice successively with the mouse unmoved. The bit 4 of LD0A CR-E0 determines which button (left or right) to perform wake-up function.
Publication Release Date: March 1998
- 69 - Revision 0.62
Page 79
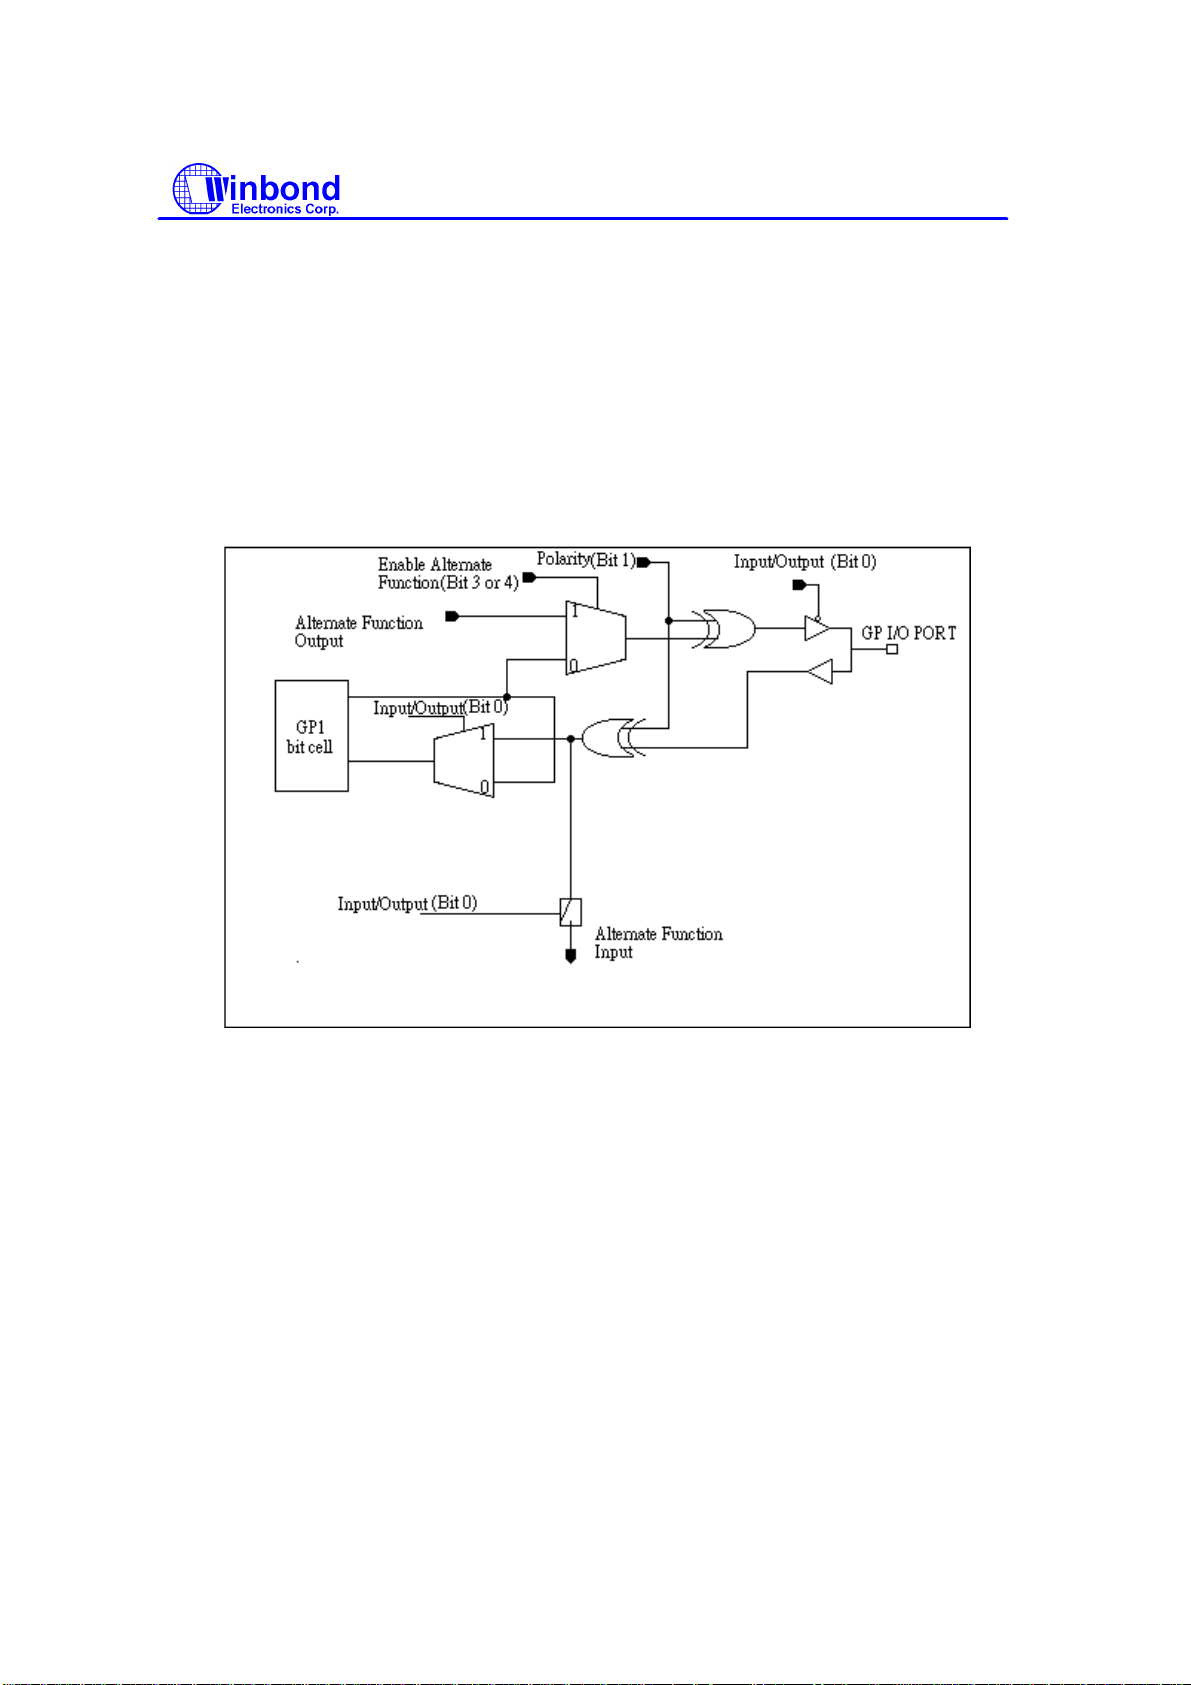
W83977TF
PRELIMINARY
7. GENERAL PURPOSE I/O
W83977TF provides 23 Input/Output ports that can be individually configured to perform a simple
basic I/O function or a pre-defined alternate function. Those 23 GP I/O ports are divided into three
groups, the first group contains 8 ports, the second group contains only 7 ports, and the third group
contains 8 ports. Each port in first group corresponds to a configuration register in logical device 7,
the second group in logical device 8, and the third group in logical device 9. Users can select those
I/O ports functions by independently programming those configuration registers. Figure 7.1, 7.2, and
7.3 respectively show the GP I/O port's structure of logical device 7, 8, and 9. Right after Power-on
reset, those ports default to perform basic I/O functions.
Figure 7.1
Publication Release Date:March 1998
-69 - Revision 0.62
Page 80
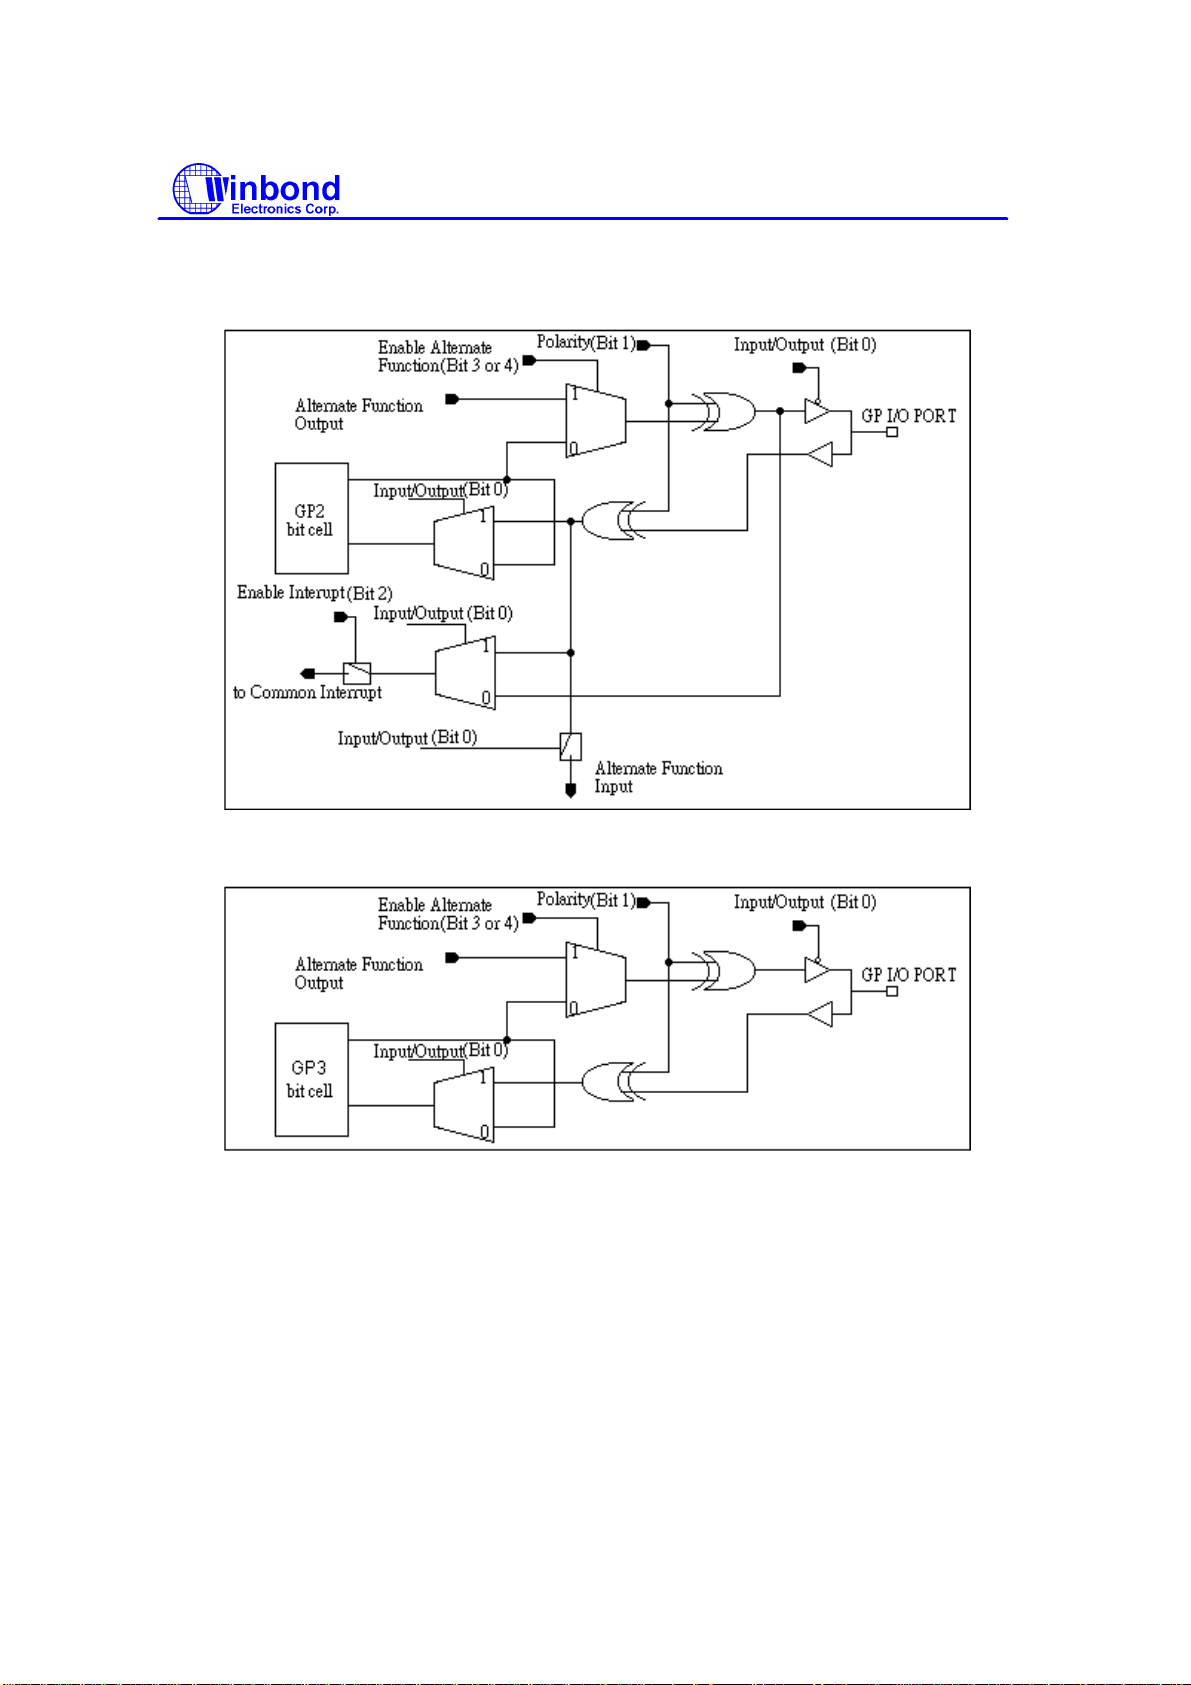
W83977TF
PRELIMINARY
Figure 7.2
Figure 7.3
Publication Release Date:March 1998
-70 - Revision 0.62
Page 81
W83977TF
PRELIMINARY
7.1 Basic I/O functions
The Basic I/O functions of W83977TF provide several I/O operations including driving a logic value to
output port, latching a logic value from input port, inverting the input/output logic value, and steering
Common Interrupt (only available in the second group of the GP I/O port). Common Interrupt is the
ORed function of all interrupt channels in the second group of the GP I/O ports, and it also connects
to a 1ms debounce filter which can reject a noise of 1 ms pulse width or less. There are three 8-bit
registers (GP1, GP2, and GP3) which are directly connected to those GP I/O ports. Each GP I/O port
is represented as a bit in one of three 8-bit registers. Only 6 bits of GP2 are implemented. Table
7.1.1 shows their combinations of Basic I/O functions, and Table 7.1.2 shows the register bit
assignments of GP1, GP2, and GP3.
Table 7.1.1
I/O BIT
0 = OUTPUT
1 = INPUT
0 0 0 Basic non-inverting output
0 0 1 Basic inverting output
0 1 0 Non-inverted output bit value of GP2
0 1 1 Inverted output bit value of GP2 drive
1 0 0 Basic non-inverting input
1 0 1 Basic inverting input
1 1 0 Non-inverted input drive to Common
1 1 1 Inverted input drive to Common
ENABLE INT BIT
0 = DISABLE
1 = ENABLE
POLARITY BIT
0 = NON INVERT
1 = INVERT
BASIC I/O OPERATIONS
drive to Common Interrupt
to Common Interrupt
Interrupt
Interrupt
Publication Release Date:March 1998
-71 - Revision 0.62
Page 82
PRELIMINARY
Table 7.1.2
W83977TF
GP I/O PORT ACCESSED
REGISTER
BIT 0 GP10
BIT 1 GP11
BIT 3 GP13
GP1 BIT 4 GP14
BIT 5 GP15
BIT 6 GP16
BIT 7 GP17
BIT 0 GP20
BIT 1 GP21
GP2 BIT 2 GP22
BIT 3 GP23
BIT 4 GP24
BIT 5 GP25
REGISTER BIT
ASSIGNMENT
BIT 2 GP12
GP I/O PORT
BIT 6 GP26
BIT 0 GP30
BIT 1 GP31
BIT 2 GP32
BIT 3 GP33
GP3 BIT 4 GP34
BIT 6 GP36
BIT 7 GP37
BIT 5 GP35
Publication Release Date:March 1998
-72 - Revision 0.62
Page 83
W83977TF
PRELIMINARY
7.2 Alternate I/O Functions
W83977TF provides several alternate functions which are scattered among the GP I/O ports. Table
7.2.1 shows their assignments. Polarity bit can also be set to alter their polarity.
Table 7.2.1
GP I/O PORT ALTERNATE FUNCTION
GP10 Interrupt Steering
GP11 Interrupt Steering
GP12 Watch Dog Timer Output/IRRX input
GP13 Power LED output/IRTX output
GP14 General Purpose Address Decoder/Keyboard Inhibit(P17)
GP15 General Purpose Write Strobe/ 8042 P12
GP16 Watch Dog Timer Output
GP17 Power LED output
GP20 Keyboard Reset (8042 P20)
GP21 8042 P13
GP22 8042 P14
GP23 8042 P15
GP24 8042 P16
GP25 GATE A20 (8042 P21)
GP30 Interrupt Steering
GP31 Interrupt Steering
GP32 General Purpose Address Decoder
GP33 General Purpose Address Decoder
GP34 Watch Dog Timer Output
7.2.1 Interrupt Steering
GP10, GP11, GP30, and GP31 can be programmed to map their own interrupt channels. The
selection of IRQ channel can be done in configuration registers CR70 and CR72 of logical device 7
and logical device 9. Each interrupt channel also has its own 1 ms debounce filter that is used to
reject any noise whose width is equal to or less than 1 ms.
Publication Release Date:March 1998
-73 - Revision 0.62
Page 84
W83977TF
PRELIMINARY
IOW
7.2.2 Watch Dog Timer Output
Watch Dog Timer contains a one minute resolution down counter, CRF2 of Logical Device 8, and two
watch Dog control registers, WDT_CTRL0 and WDT_CTRL1 of Logical Device 8. The down counter
can be programmed within the range from 1 to 255 minutes. Writing any new non-zero value to
CRF2 or reset signal coming from a Mouse interrupt or Keyboard interrupt (CRF2 also contains nonzero value) will cause the Watch Dog Timer to reload and start to count down from the new value. As
the counter reaches zero, (1) Watch Dog Timer time-out occurs and the bit 0 of WDT_CTRL1 will be
set to logic 1; (2) Watch Dog interrupt output is asserted if the interrupt is enable in CR72 of logical
device 8; and (3) Power LED starts to toggle output if the bit 3 of WDT_CTRL0 is enabled.
WDT_CTRL1 also can be accessed through GP2 I/O base address + 1.
7.2.3 Power LED
The Power LED function provides 1 Hertz rate toggle pulse output with 50 percent duty cycle. Table
7.2.2 shows how to enable Power LED.
Table 7.2.2
WDT_CTRL1 BIT[1] WDT_CTRL0 BIT[3] WDT_CTRL1 BIT[0] POWER LED STATE
* Note: Continuous high or low depends on the polarity bit of GP13 or GP17 configuration registers.
1 X X 1 Hertz Toggle pulse
0 0 X Continuous high or low *
0 1 0 Continuous high or low *
0 1 1 1 Hertz Toggle pulse
7.2.4 General Purpose Address Decoder
General Purpose Address Decoder provides two address decode as AEN equal to logic 0. The
address base is stored at CR62, CR63 of logical device 7 for GP14 and at CR62-65 of logical device
9 for GP32 and GP33. The decoding output is normally active low. Users can alter its polarity
through the polarity bit of the GP14, GP32, and GP33's configuration register.
7.2.5 General Purpose Write Strobe
General Purpose Write Strobe is an address decoder that performs like General Purpose Address
Decoder, but it has to be qualified by
alter its polarity through the polarity bit of the GP15's configuration register.
and AEN. Its output is normally active low. Users can
Publication Release Date:March 1998
-74 - Revision 0.62
Page 85
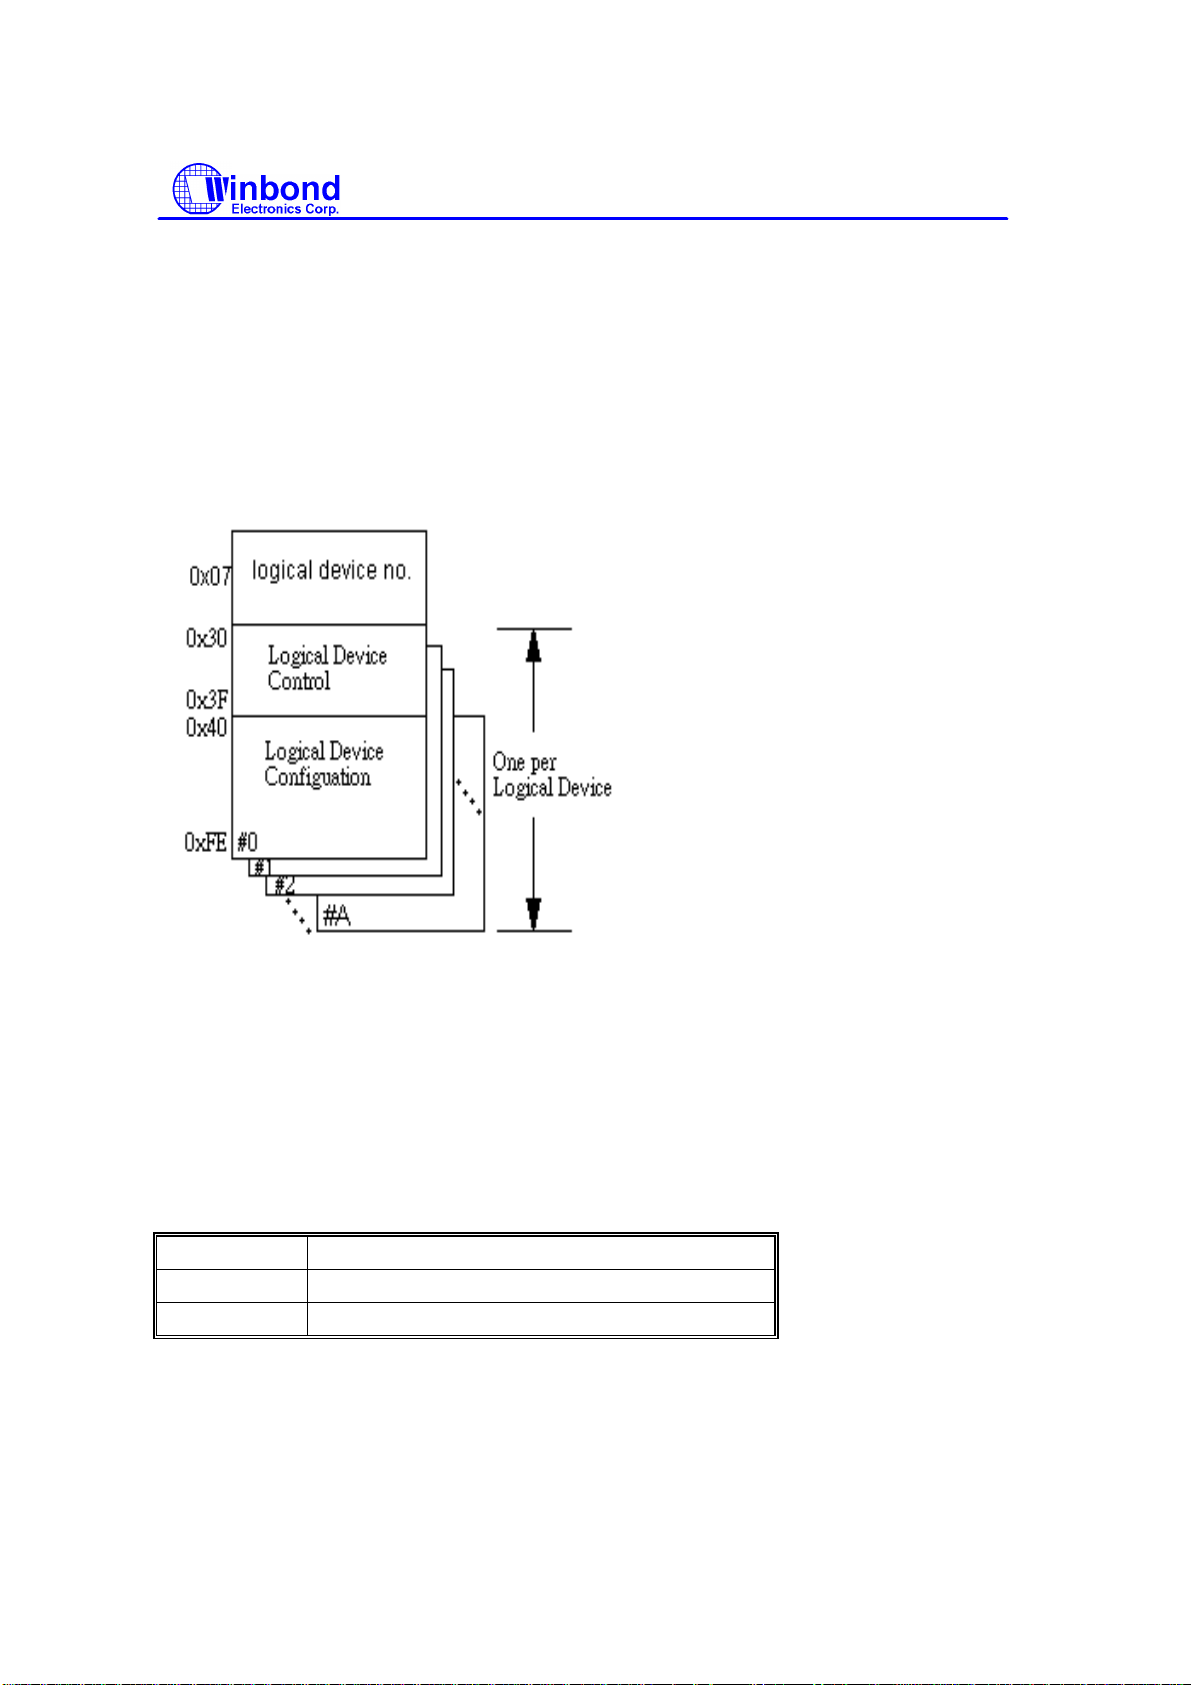
W83977TF
PRELIMINARY
8. PLUG AND PLAY CONFIGURATION
The W83977TF uses Compatible PNP protocol to access configuration registers for setting up
different types of configurations. In W83977TF, there are nine Logical Devices (from Logical Device
0 to Logical Device A with the exception of logical device 4 and 6 for compatibility) which correspond
to nine individual functions: FDC (logical device 0), PRT (logical device 1), UART1 (logical device 2),
UART2 (logical device 3), KBC (logical device 5), GPIO1 (logical device 7), GPIO2 (logical device 8),
GPIO3 (logical device 9), and ACPI ((logical device A). Each Logical Device has its own
configuration registers (above CR30). Host can access those registers by writing an appropriate
logical device number into logical device select register at CR7.
8.1 Compatible PnP
8.1.1 Extended Function Registers
In Compatible PnP, there are two ways to enter Extended Function and read or write the configuration
registers. HEFRAS (CR26 bit 6) can be used to select one out of these two methods of entering the
Extended Function mode as follows:
HEFRAS address and value
0 write 87h to the location 3F0h twice
1 write 87h to the location 370h twice
Publication Release Date:March 1998
-75 - Revision 0.62
Page 86
W83977TF
PRELIMINARY
RTSA
After Power-on reset, the value on
PnP, a specific value (87h) must be written twice to the Extended Functions Enable Register (I/O port
address 3F0h or 370h). Secondly, an index value (02h, 07h-FFh) must be written to the Extended
Functions Index Register (I/O port address 3F0h or 370h same as Extended Functions Enable
Register) to identify which configuration register is to be accessed. The designer can then access the
desired configuration register through the Extended Functions Data Register (I/O port address 3F1h
or 371h).
After programming of the configuration register is finished, an additional value (AAh) should be
written to EFERs to exit the Extended Function mode to prevent unintentional access to those
configuration registers. The designer can also set bit 5 of CR26 (LOCKREG) to high to protect the
configuration registers against accidental accesses.
The configuration registers can be reset to their default or hardware settings only by a cold reset (pin
MR = 1). A warm reset will not affect the configuration registers.
8.1.2 Extended Functions Enable Registers (EFERs)
After a power-on reset, the W83977TF enters the default operating mode. Before the W83977TF
enters the extended function mode, a specific value must be programmed into the Extended Function
Enable Register (EFER) so that the extended function register can be accessed. The Extended
Function Enable Registers are write-only registers. On a PC/AT system, their port addresses are
3F0h or 370h (as described in previous section).
8.1.3 Extended Function Index Registers (EFIRs), Extended Function Data Registers(EFDRs)
After the extended function mode is entered, the Extended Function Index Register (EFIR) must be
loaded with an index value (02h, 07h-FEh) to access Configuration Register 0 (CR0), Configuration
Register 7 (CR07) to Configuration Register FE (CRFE), and so forth through the Extended Function
Data Register (EFDR). The EFIRs are write-only registers with port address 3F0h or 370h (as
described in section 8.1.1) on PC/AT systems; the EFDRs are read/write registers with port address
3F1h or 371h (as described in section 8.1.1) on PC/AT systems.
(pin 43) is latched by HEFRAS of CR26. In Compatible
Publication Release Date:March 1998
-76 - Revision 0.62
Page 87
W83977TF
PRELIMINARY
SMI
SCI
SMI
SCI
SMI
SMI
SMI
SMI
SCI
SCI
SCI
SCI
9. ACPI REGISTERS FEATURES
W83977TF supports both ACPI and legacy power managements. The switch logic of the power
managment block generates an
mode. For the legacy mode, the SMI_EN bit is used. If it is set, it routes the power management
events to the
interrupt logic. For the ACPI mode, the SCI_EN bit is used. If it is set, it route the
power management events to the
register block of Device A and the SCI_EN bit is located in the PM1 register block. See the following
figure for illustration.
from SCI to SMI
IRQs
SMI Logic
0
interrupt in the legacy mode and an
interrupt in the ACPI
interrupt logic. The SMI_EN bit is located in the configuration
SMI_EN
IRQs
SMI output
Logic
SMI
PM Timer
from SMI to SCI
Bus Master SCI
Device Idle
Timers
1
SCI_EN
SCI Logic
IRQs
SCI output
Logic
Sleep/Wake
State machine
SCI
WAK_STS
Clock
Control
Device Trap
Global STBY
Timer
The
to output the
The
interrupt is routed to pin
interrupt is to route to pin IRQSER, which is the signal pin in the Serial IRQ mode.
interrupt can be routed to pin
, which is dedicated for the
, which is dedicated for the
interrupt output. Another way
function. Or it can be
routed to one interrupt request pin, which is selected through CR70.bit3 - 0 of logical device 9.
Another way is to output the
interrupt to pin IRQSER if serial IRQ mode is enabled.
Publication Release Date:March 1998
-77 - Revision 0.62
Page 88
W83977TF
PRELIMINARY
SMI
SCI
SCI
SMI
clear
SCI
9.1 SMI to SCI/SCI to SMI and Bus Master
The following figure illustrates the process of generating an interrupt from
.
from SMI to SCI
BIOS_RLS
GBL_EN
from SCI to SMI
GBL_RLS
BIOS_EN
BUS Master SCI
BM_CNTPL
set
clear
set
clear
set
GBL_STS
To SCI Logic
BIOS_STS
To SMI Logic
BM_STS
To SCI Logic
to
or from
to
BM_RLD
: Status bit
: Enable bit
For the BIOS software to raise an event to the ACPI software, BIOS_RLS, GBL_EN, and GBL_STS
bits are involved. GBL_EN is the enable bit and the GBL_STS is the status bit. Both are controlled
by the ACPI software. If BIOS_RLS is set by the BIOS software and GBL_EN is set by the ACPI
software, an
GBL_STS to logic 1. Writing a 0 to BIOS_RLS has no effect. Wrinting a 1 to GBL_STS clears it to
logic 0 and also clears BIOS_RLS to logic 0. Writing a 0 to GBL_STS has no effect.
interrupt is raised. Writing a 1 to BIOS_RLS sets it to logic 1 and also sets
Publication Release Date:March 1998
-78 - Revision 0.62
Page 89
W83977TF
PRELIMINARY
SMI
SCI
SCI
For the ACPI software to raise an event to the BIOS software, GBL_RLS, BIOS_EN, and BIOS_STS
bits are involved. BIOS_EN is the enable bit and the BIOS_STS is the status bit. Both are controlled
by the BIOS software. If GBL_RLS is set by the ACPI software and BIOS_EN is set by the BIOS
software, an
logic 1. Writing a 0 to GBL_RLS has no effect. Wrinting a 1 to BIOS_STS clears it to logic 0 and
also clears GBL_RLS to logic 0. Writing a 0 to BIOS_STS has no effect.
For the bus master to raise an event to the ACPI software, BM_CNTRL, BM_RLD, and BM_STS bits
are involved. Both BM_RLD and BM_STS are controlled by the ACPI software. If BM_CNTRL is set
by the BIOS software and BM_RLD is set by the ACPI software, an
1 to BM_CNTRL sets it to logic 1 and also sets BM_STS to logic 1. Writing a 0 to BM_CNTRL has no
effect. Wrinting a 1 to BM_STS clears it to logic 0 and also clears BM_CNTRL to logic 0. Writing a 0
to BM_STS has no effect.
is raised. Writing a 1 to GBL_RLS sets it to logic 1 and also sets BIOS_STS to
interrupt is raised. Writing a
9.2 Power Management Timer
In the ACPI specification, it requires a power management timer. The power management timer is a
24-bit fixed rate free running up-count timer that runs off a 3.579545MHZ clock. The power
management timer corresponds to status bit (TMR_STS) and enable bit (TMR_EN). The TMR_STS
bit is set any time the last bit of the timer (bit 23) goes from 0 to 1 or from 1 to 0. If the TMR_EN bit
is set, the setting of the TMR_STS bit will generate an
read the timer value which are located in the PM1 register block. The power management timer has
one enabel bit (TMR_ON) to turn ii on or off. The TMR_ON is located in GPE register block. If it is
cleared to 0, the power management timer function would not work. There are no timer reset
requirements, except that the timer should function after power-up. See the following figure for
illustration.
TMR_ON
3.579545 MHz
24 bit
counter
Bits (23-0)
24
TMR_VAL
interrupt. Three registers are used to
TMR_STS
To SCI Logic
TMR_EN
Publication Release Date:March 1998
-79 - Revision 0.62
Page 90
W83977TF
PRELIMINARY
SCI
SCI
SCI
SCI
9.3 ACPI Registers (ACPIRs)
The ACPI register model consists of the fixed register blocks that perform the ACPI functuions. A
register block may be a event register block which deals with ACPI events or a control register block
which deals with control features. The order in the event register block is a status register followed by
an enable register.
Each event register, if implemented, contains two two register: a status register and an enable
register, of 16 bits wide each. The status register indicates which event triggers the ACPI System
Control Interrupt (
However, the corresponding enable bit is also required to be set before an
raised. If the enable bit is not set, the software can examine the state of the hardware event by
reading the status bit without generating an
Any status bit, unless otherwise noted, can only be set by specific hardware event. It is cleared by
writing a 1 to its bit position and writing a 0 has no effect. Except some special status bits, every
status bit has the corresponding enable bit on the same bit position in the enable register. Those
status bits which have no corresponding enable bit are read for special purpose. Reverved or
unimplemented enable bits always return zero, and writing to these bits should has no effect.
The control bit in the control register provides some special control function over the hardware event,
or some special control over
and writing to those bits should has no effect.
Table 9-1 (sec. 9.3.21) lists the PM1 register block and its registers. The base address of PM1
register block is named as PM1a_EVT_BLK in the ACPI specification and is specified in CR60, 61 of
logical device A.
Table 9-2 (sec. 9.3.21) lists the GPE register block and its registers. The base address of generalpurpose event block GPE0 is named as GPE0_BLK in the ACPI specification and is specified in
CR62, 63 of logical device A. The base address of general-purpose event block GPE1 is named as
GPE1_BLK in the ACPI specification and is specified in CR64, 65 of logical device A.
). When the hardware event occurs, the corresponding status bit will be set.
interrupt could be
interrupt.
event. Reserved or unimplemented control bits always return zero,
9.3.1 Power Management 1 Status Register 1 (PM1STS1)
Register Location: <CR60, 61> System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
34567
1
-80 - Revision 0.62
0
TMR_STS
Reserved
Reserved
Reserved
BM_STS
GBL_STS
Reserved
Reserved
Publication Release Date:March 1998
Page 91
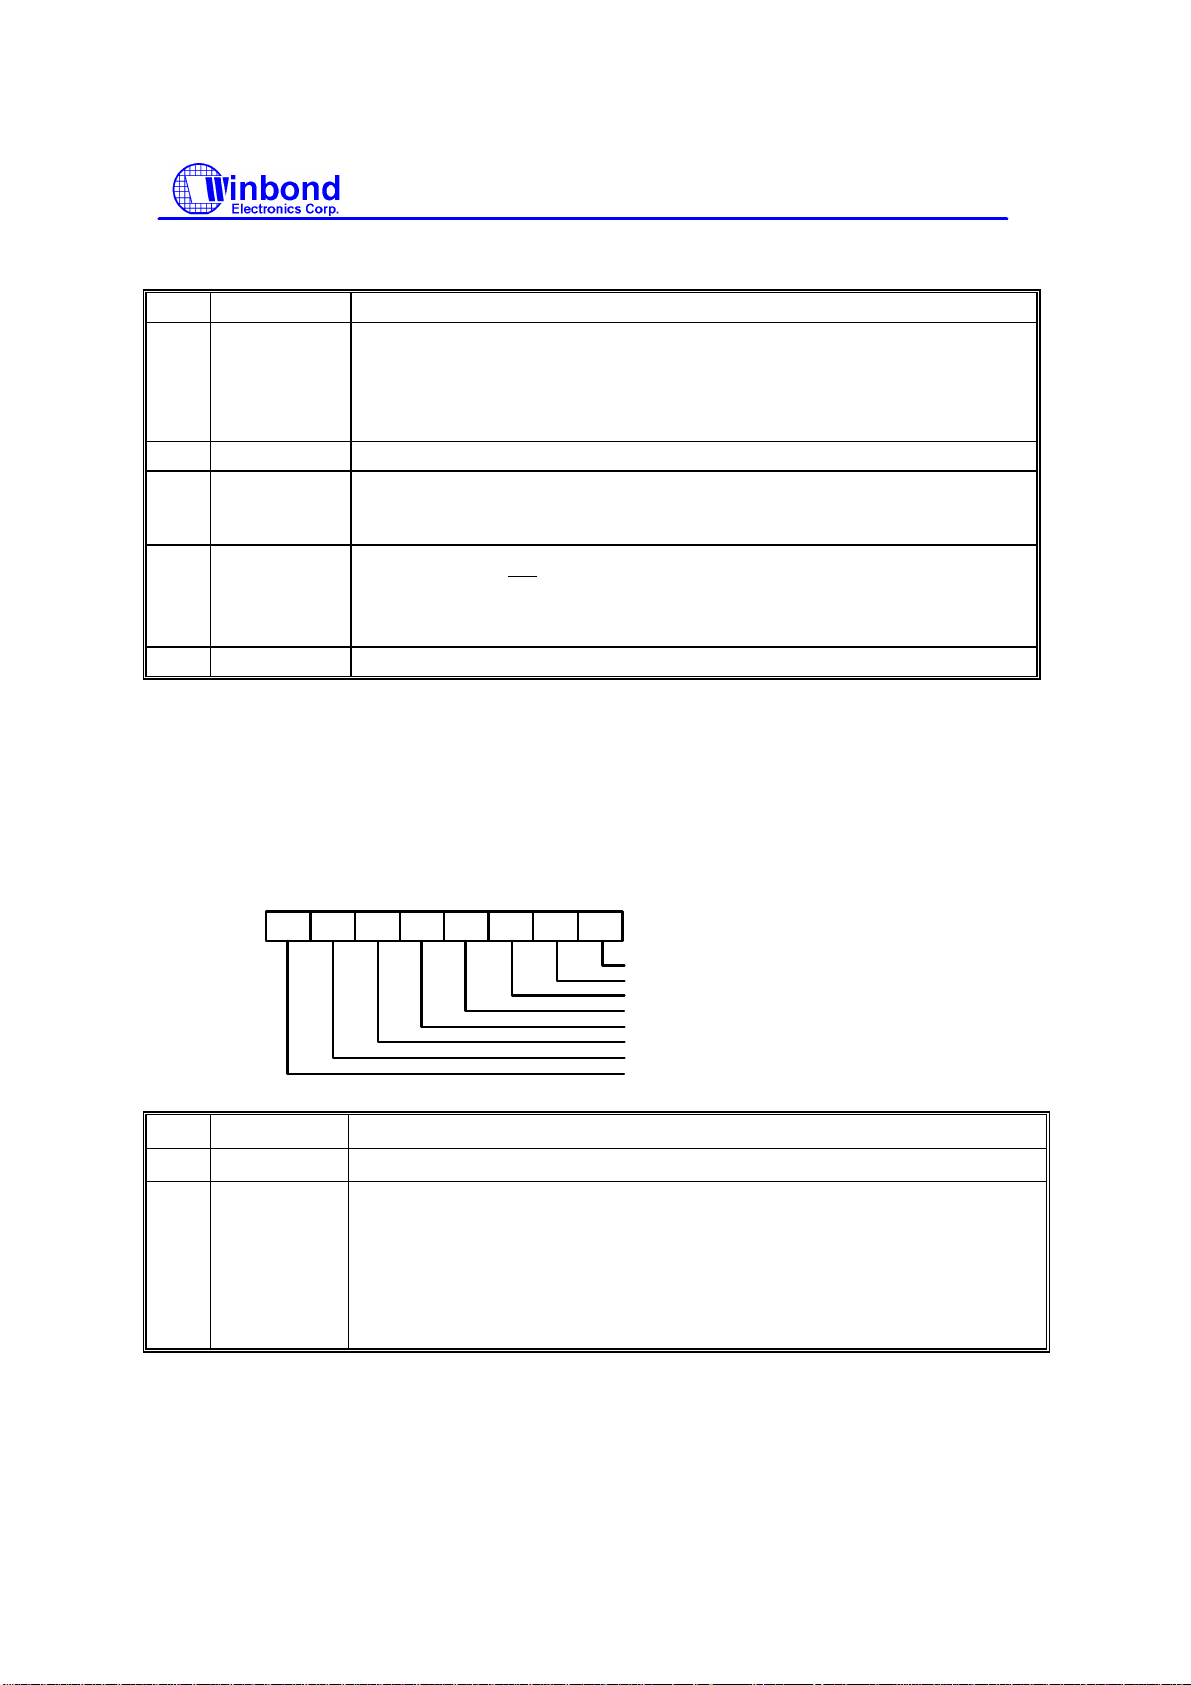
W83977TF
PRELIMINARY
SCI
Bit Name Description
0 TMR_STS This bit is the timer carry status bit. This bit is set anytime the bit 23 of the
24-bit counter changes (whenever the MSB changes from low to high or high
to low). When TMR_EN and TMR_STS are set, a power magement event is
raised. This bit is only set by hardware and can only be cleared by writing a
1 to this bit position. Writing a 0 has no effect.
1-3 Reserved Reserved.
4 BM_STS This is the bus master status bit. Writing a 1 to BM_CNTRL also sets
BM_STS. Writing a 1 clears this bit and also clears BM_CNTRL. Writing a
0 has no effect.
5 GBL_STS This is the global status bit. This bit is set when the BIOS wants the
attention of the
can only be cleared by writing a 1 to this bit position. Writing a 1 to this bit
position also clears BIOS_RLS. Writing a 0 has no effect.
6-7 Reserved Reserved. These bits always return zeros.
9.3.2 Power Management 1 Status Register 2 (PM1STS2)
Register Location: <CR60, 61> + 1H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
34567
handler. BIOS sets this bit by setting BIOS_RLS and
2
1
0
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
WAK_STS
Bit Name Description
0-6 Reserved Reserved.
7 WAK_STS This bit is set when the system is in the sleeping state and an enabled resume
event occurs. Upon setting this bit, the sleeping/working state machine will
transition the system to the working state. This bit is only set by hardware and
is cleared by writing a 1 to this bit position or by the sleeping/working state
machine automatically when the global standby timer expires. Writing a 0 has
no effect. When the WAK_STS is cleared and all devices are in sleeping
state, the whole chip enters the sleeping state.
Publication Release Date:March 1998
-81 - Revision 0.62
Page 92
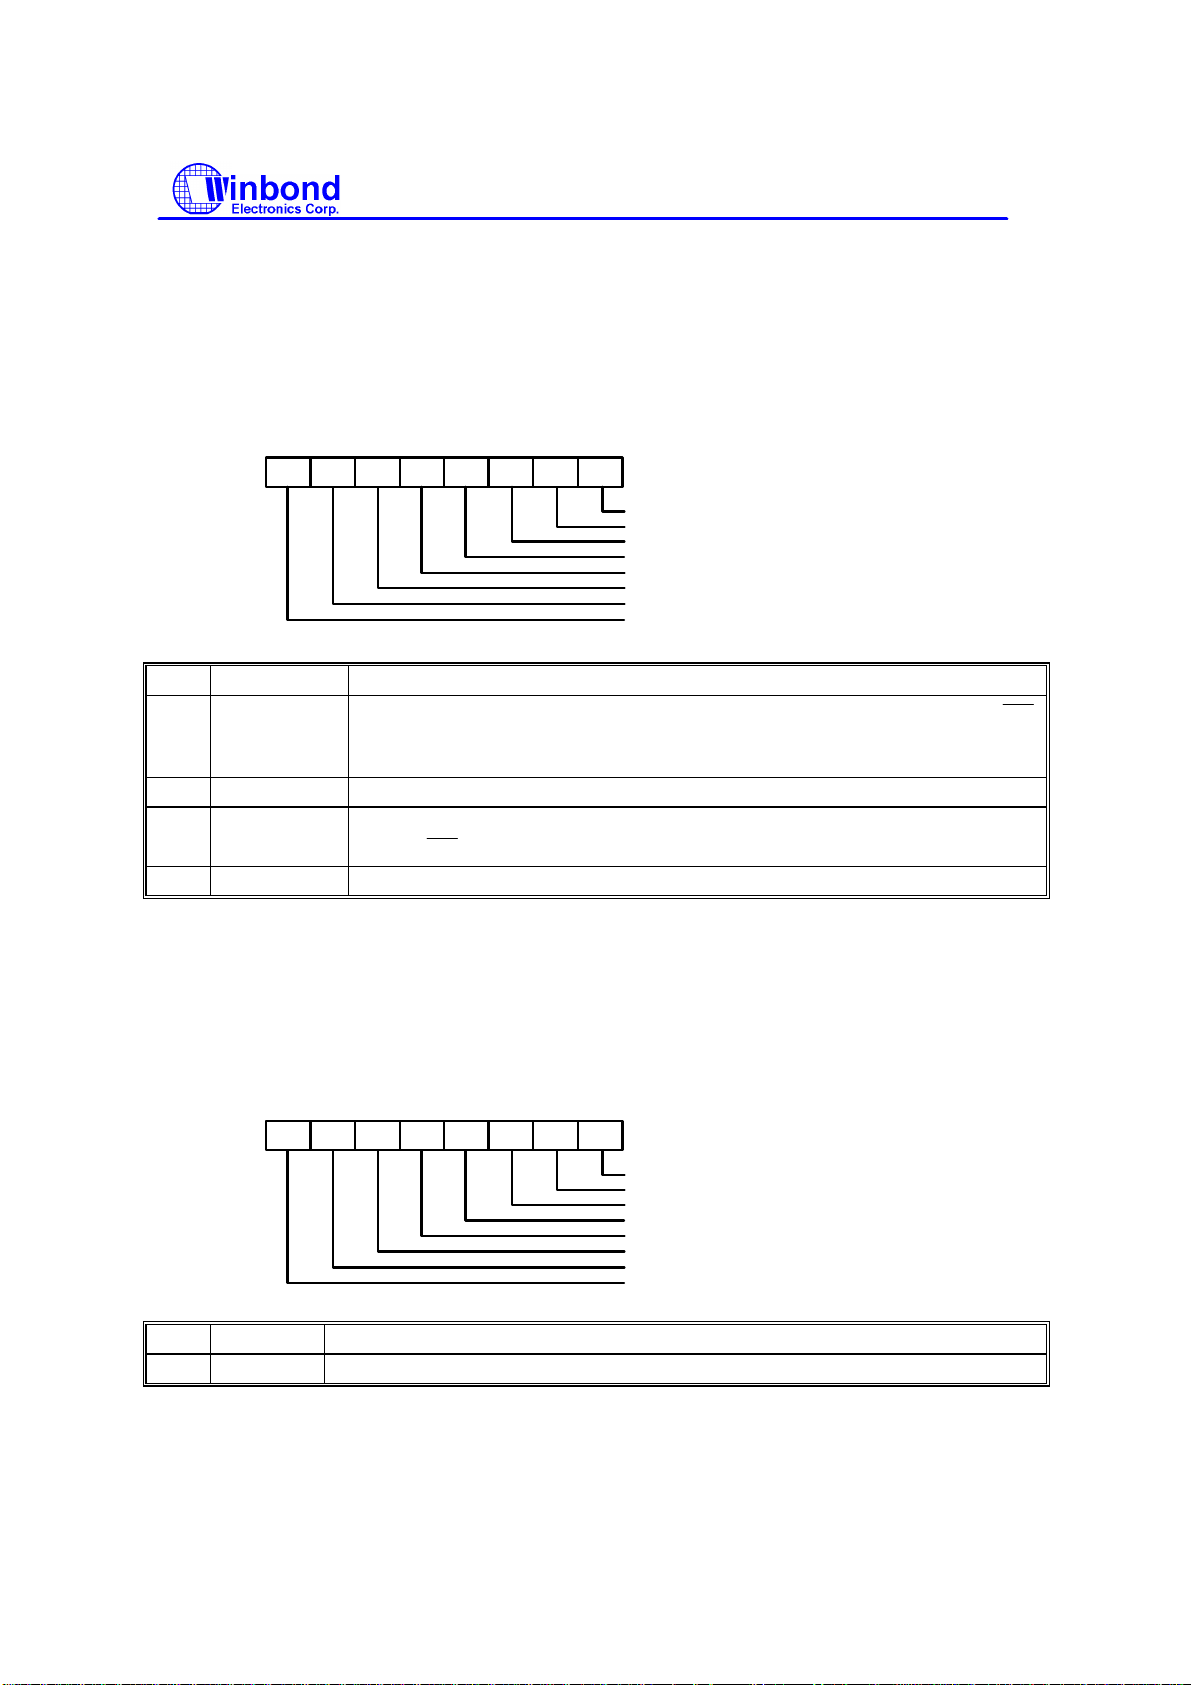
W83977TF
PRELIMINARY
SCI
SCI
9.3.3 Power Management 1 Enable Register 1(PM1EN1)
Register Location: <CR60, 61> + 2H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
1
0
34567
Bit Name Description
0 TMR_EN
This is the timer carry interrupt enable bit. When this bit is set then an
event is generated whenever the TMR_STS bit is set. When this bit is reset
then no interrupt is generated even when the TMR_STS bit is set.
1-4 Reserved Reserved. These bits always return a value of zero.
5 GBL_EN The global enable bit. When both the GBL_EN bit and the GBL_STS bit are
set, an
interrupt is raised.
6-7 Reserved Reserved.
TMR_EN
Reserved
Reserved
Reserved
GBL_EN
Reserved
Reserved
Reserved
9.3.4 Power Management 1 Enable Register 2 (PM1EN2)
Register Location: <CR60, 61> + 3H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
1
0
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
34567
Bit Name Description
0-7 Reserved Reserved. These bits always return zeros.
-82 - Revision 0.62
Publication Release Date:March 1998
Page 93
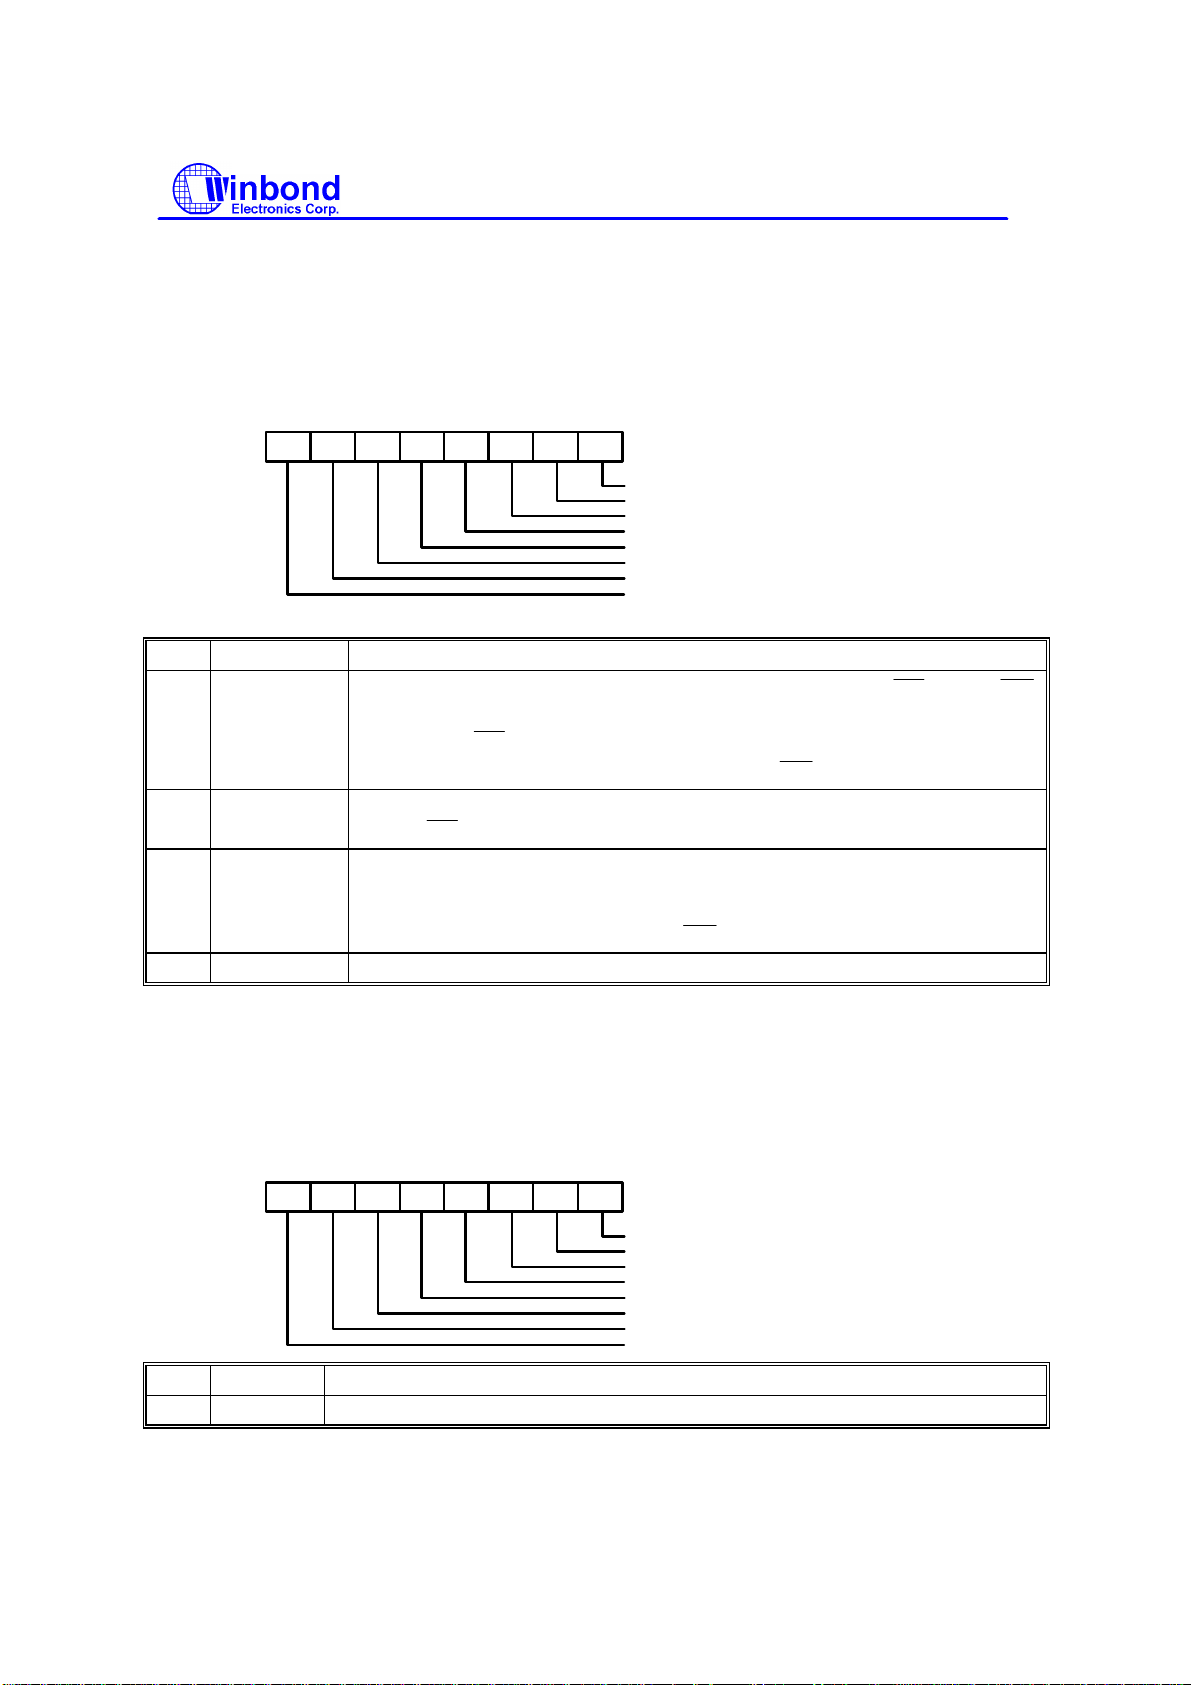
W83977TF
PRELIMINARY
SCI
SMI
SCI
SMI
SCI
SMI
9.3.5 Power Management 1 Control Register 1 (PM1CTL1)
Register Location: <CR60, 61> + 4H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
1
0
34567
Bit Name Description
0 SCI_EN
Select whether the power management event triggers an
interrupt. When this bit is set, then the power management events will
generate an
interrupt. When this bit is reset and SMI_EN bit is set, then
the power management events will generate an
1 BM_RLD This is the bus master reload enable bit. If this bit is set and BM_CNTRL is
set, an
interrupt is raised.
2 GBL_RLS The global release bit. This bit is used by the ACPI software to raise an event
to the BIOS software. The BIOS software has a corresponding enable and
status bit to control its ability to receive the ACPI event. Setting GBL_RLS
sets BIOS_STS, and it generates an
3-7 Reserved Reserved. These bits always return zeros.
SCI_EN
BM_RLD
GBL_RLD
Reserved
Reserved
Reserved
Reserved
Reserved
or an
interrupt.
interrupt if BIOS_EN is also set.
9.3.6 Power Management 1 Control Register 2 (PM1CTL2)
Register Location: <CR60, 61> + 5H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
1
0
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
34567
Bit Name Description
0-7 Reserved Reserved. These bits always return zeros.
-83 - Revision 0.62
Publication Release Date:March 1998
Page 94
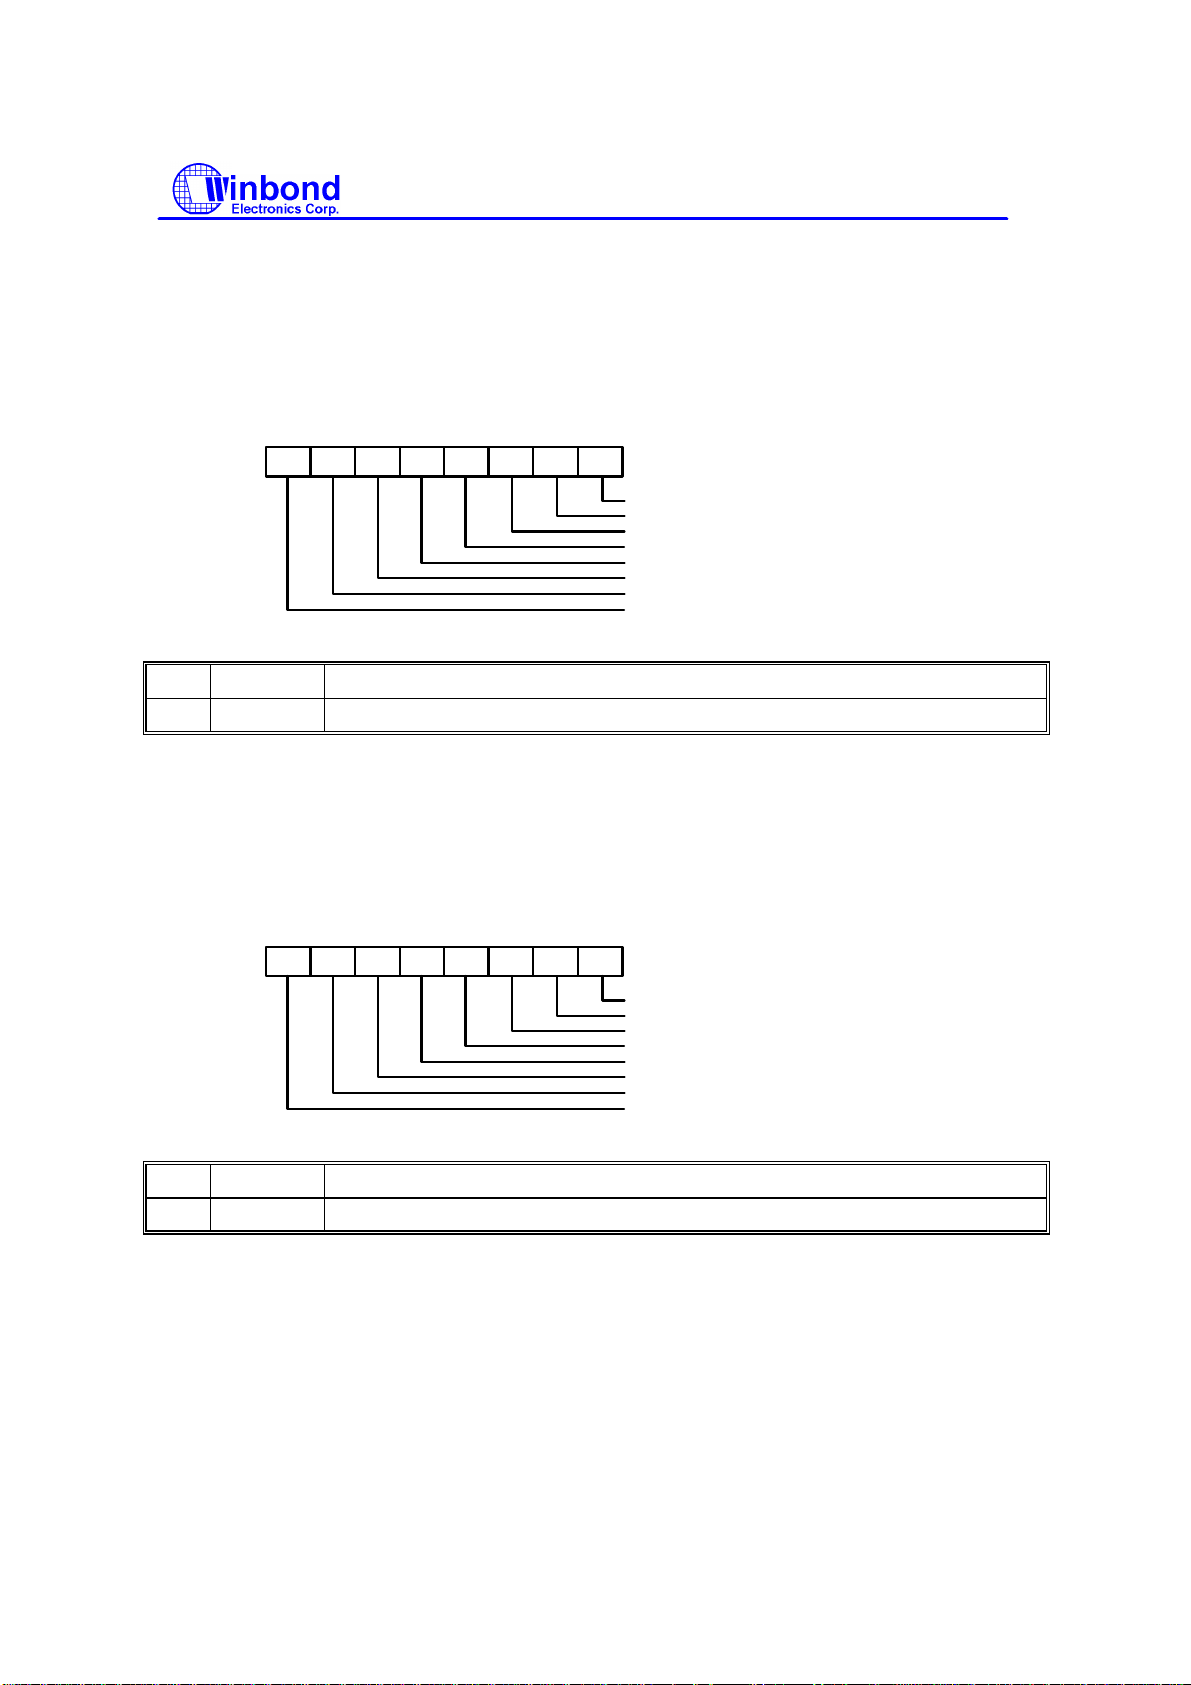
PRELIMINARY
9.3.7 Power Management 1 Control Register 3 (PM1CTL3)
Register Location: <CR60, 61> + 6H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
1
0
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
34567
Bit Name Description
0-7 Reserved Reserved. These bits always return zeros.
9.3.8 Power Management 1 Control Register 4 (PM1CTL4)
Register Location: <CR60, 61> + 7H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
34567
1
0
W83977TF
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Bit Name Description
0-7 Reserved Reserved. These bits always return zeros.
-84 - Revision 0.62
Publication Release Date:March 1998
Page 95
PRELIMINARY
Bit
SCI
W83977TF
9.3.9 Power Management 1 Timer 1 (PM1TMR1)
Register Location: <CR60, 61> + 8H System I/O Space
Default Value: 00h
Attribute: Read only
Size: 8 bits
2
1
0
34567
Name Description
0-7 TMR_VAL This read-only field returns the running count of the power management timer.
This is a 24-bit counter that runs off of a 3.579545 MHZ clock, and counts in
the working state. The timer is reset and then continues counting until the
CLKIN input the the chip is stopped. If the clock is restarted without a MR
reset, then the counter will resume counting from where it stopped. The
TMR_STS bit is set any time the last bit of the timer (bit 23) goes from 0 to 1
or from 1 to 0. If the TMR_EN bit is set, the setting of the TMR_STS bit will
generate an
interrupt.
TMR_VAL0
TMR_VAL1
TMR_VAL2
TMR_VAL3
TMR_VAL4
TMR_VAL5
TMR_VAL6
TMR_VAL7
9.3.10 Power Management 1 Timer 2 (PM1TMR2)
Register Location: <CR60, 61> + 9H System I/O Space
Default Value: 00h
Attribute: Read only
Size: 8 bits
2
34567
1
0
TMR_VAL8
TMR_VAL9
TMR_VAL10
TMR_VAL11
TMR_VAL12
TMR_VAL13
TMR_VAL14
TMR_VAL15
-85 - Revision 0.62
Publication Release Date:March 1998
Page 96
PRELIMINARY
Bit
SCI
Bit
SCI
W83977TF
Name Description
0-7 TMR_VAL This read-only field returns the running count of the power management timer.
This is a 24-bit counter that runs off of a 3.579545 MHZ clock, and counts in
the working state. The timer is reset and then continues counting until the
CLKIN input the the chip is stopped. If the clock is restarted without a MR
reset, then the counter will resume counting from where it stopped. The
TMR_STS bit is set any time the last bit of the timer (bit 23) goes from 0 to 1
or from 1 to 0. If the TMR_EN bit is set, the setting of the TMR_STS bit will
generate an
interrupt.
9.3.11 Power Management 1 Timer 3 (PM1TMR3)
Register Location: <CR60, 61> + AH System I/O Space
Default Value: 00h
Attribute: Read only
Size: 8 bits
2
34567
1
0
TMR_VAL16
TMR_VAL17
TMR_VAL18
TMR_VAL19
TMR_VAL20
TMR_VAL21
TMR_VAL22
TMR_VAL23
Name Description
0-7 TMR_VAL This read-only field returns the running count of the power management timer.
This is a 24-bit counter that runs off of a 3.579545 MHZ clock, and counts in
the working state. The timer is reset and then continues counting until the
CLKIN input the the chip is stopped. If the clock is restarted without a MR
reset, then the counter will resume counting from where it stopped. The
TMR_STS bit is set any time the last bit of the timer (bit 23) goes from 0 to 1
or from 1 to 0. If the TMR_EN bit is set, the setting of the TMR_STS bit will
generate an
interrupt.
Publication Release Date:March 1998
-86 - Revision 0.62
Page 97
PRELIMINARY
9.3.12 Power Management 1 Timer 4 (PM1TMR4)
SCI
SCI
SCI
SCI
SCI
Register Location: <CR60, 61> + BH System I/O Space
Default Value: 00h
Attribute: Read only
Size: 8 bits
2
34567
1
0
Bit Name Description
0-7 Reserved Reserved. These bits always return zeros.
9.3.13 General Purpose Event 0 Status Register 1 (GP0STS1)
Register Location: <CR62, 63> System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
34567
1
0
W83977TF
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
URBSCISTS
URASCISTS
FDCSCISTS
PRTSCISTS
KBCSCISTS
MOUSCISTS
Reserved
Reserved
These bits indicate the status of the
corresponding enable bit in the
input, which is set when the device's IRQ is raised. If the
interrupt enable register (in GP0EN1) is set, an
interrupt is
raised and routed to the output pin. Wrinting a 1 clears the bit, and wrinting a 0 has no effect. If the
bit is not cleared, new IRQ to the
logic input is ignored and no
interrupt will be raised.
Publication Release Date:March 1998
-87 - Revision 0.62
Page 98
PRELIMINARY
SCI
SCI
SCI
SCI
SCI
SCI
Bit Name Description
0 URBSCISTS
1 URASCISTS
2 FDCSCISTS
3 PRTSCISTS
4 KBCSCISTS
5 MOUSCISTS
UART B
UART A
FDC
PRT
KBC
MOUSE
status, which is set by the UART B IRQ.
status, which is set by the UART A IRQ.
status, which is set by the FDC IRQ.
status, which is set by the printer port IRQ.
status, which is set by the KBC IRQ.
status, which is set by the MOUSE IRQ.
6-7 Reserved Reserved.
9.3.14 General Purpose Event 0 Status Register 2 (GP0STS2)
Register Location: <CR62, 63> + 1H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
34567
1
0
W83977TF
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Bit Name Description
0-7 Reserved Reserved. These bits always return zeros.
Publication Release Date:March 1998
-88 - Revision 0.62
Page 99
PRELIMINARY
9.3.15 General Purpose Event 0 Enable Register 1 (GP0EN1)
SCI
SCI
SCI
SCI
SCI
SCI
SCI
SCI
Register Location: <CR62, 63> + 2H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
1
0
URBSCIEN
URASCIEN
FDCSCIEN
PRTSCIEN
KBCSCIEN
MOUSCIEN
Reserved
Reserved
34567
W83977TF
These bits are used to enable the device's IRQ sources into the
logic. The
logic output for
the IRQs is as follows:
SCI logic output = (URBSCIEN and URBSCISTS) or (URASCIEN and URASCISTS) or (FDCSCIEN
and FDCSCISTS) or (PRTSCIEN and PRTSCISTS) or (KBCSCIEN and KBCSCISTS) or
(MOUSCIEN and MOUSCISTS)
Bit Name Description
0 URBSCIEN
1 URASCIEN
2 FDCSCIEN
3 PRTSCIEN
4 KBCSCIEN
5 MOUSCIEN
UART B
UART A
FDC
printer port
KBC
MOUSE
enable, which controls the UART B IRQ.
enable, which controls the UART A IRQ.
enable, which controls the FDC IRQ.
enable, which controls the printer port IRQ.
enable, which controls the KBC IRQ.
enable, which controls the MOUSE IRQ.
6-7 Reserved Reserved.
9.3.16 General Purpose Event 0 Enable Register 2 (GP0EN2)
Register Location: <CR62, 63> + 3H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
Publication Release Date:March 1998
-89 - Revision 0.62
Page 100
PRELIMINARY
2
SMI
1
0
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
34567
Bit Name Description
0-7 Reserved Reserved. These bits always return zeros.
9.3.17 General Purpose Event 1 Status Register 1 (GP1STS1)
Register Location: <CR64, 65> System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
2
34567
1
0
W83977TF
BIOS_STS
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Reserved
Bit Name Description
0 BIOS_STS The BIOS status bit. This bit is set when GBL_RLS is set. If BIOS_EN is set,
setting GBL_RLS will raise an
event. Writing a 1 to its bit location clears
BIOS_STS and also clears GBL_RLS. Writing a 0 has no effect.
1-7 Reserved Reserved.
9.3.18 General Purpose Event 1 Status Register 2 (GP1STS2)
Register Location: <CR64, 65> + 1H System I/O Space
Default Value: 00h
Attribute: Read/write
Size: 8 bits
Publication Release Date:March 1998
-90 - Revision 0.62
 Loading...