

Page 1

INTEGRATED CIRCUITS
DATA SH EET
TJA1054
Fault-tolerant CAN transceiver
Preliminary specification
File under Integrated Circuits, IC18
1999 Feb 11
Page 2

Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
FEATURES
Optimized for in-car low-speed communication
• Baud rate up to 125 kBaud
• Up to 32 nodes can be connected
• Supports unshielded bus wires
• Very low Radio Frequency Interference (RFI) due to
built-in slope control function and a very good matching
of the CANL and CANH bus outputs
• Fully integrated receiver filters
• Permanent dominant monitoring of transmit data input
• Good immunity performance of ElectroMagnetic
Compatibility (EMC) in normal operating mode and in
low power modes.
Bus failure management
• Supports single-wire transmission modes with ground
offset voltages up to 1.5 V
• Automatic switching to single-wire mode in the event of
bus failures, even when the CANH bus wire is
short-circuited to V
CC
• Automatic reset to differential mode if bus failure is
removed
• Fully wake-up capability during failure modes.
GENERAL DESCRIPTION
The TJA1054 is the interface between the protocol
controller and the physical wires of the bus lines in a
Control Area Network (CAN). It is primarily intended for
low-speed applications, up to 125 kBaud, in passenger
cars. The device provides differential transmit capability
but will switch in error conditions to single-wire transmitter
and/or receiver.
The TJA1054T is pin and upwards compatible with the
PCA82C252T and the TJA1053T. This means that these
two devices can be replaced by the TJA1054T with
retention of all functions.
The most important improvements are:
• Very low RFI due to a very good matching of the CANL
and CANH bus lines outputs
• Good immunity performance of EMC, especially in low
power modes
• Fully wake-up capability during failure modes
• Extended bus failure management including
short-circuit of the CANH bus line to V
CC
• Supports easy fault localization
• Two-edge sensitive wake-up input signal via pin WAKE.
Protection
• Short-circuit proof to battery and ground in
12 V powered systems
• Thermally protected
• Bus lines protected against transients in an automotive
environment
• An unpowered node does not disturb the bus lines.
Support for low power modes
• Low current sleep and standby mode with wake-up via
the bus lines
• Power-on reset flag on the output.
ORDERING INFORMATION
TYPE
NUMBER
NAME DESCRIPTION VERSION
PACKAGE
TJA1054T SO14 plastic small outline package; 14 leads; body width 3.9 mm SOT108-1
1999 Feb 11 2
Page 3

Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
QUICK REFERENCE DATA
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
V
CC
V
BAT
I
BAT
V
CANH
V
CANL
∆V
CANH
∆V
CANL
t
PD
t
r
t
f
T
amb
supply voltage on pin V
CC
battery voltage on pin BAT no time limit −0.3 − +40 V
operating mode 5.0 − 27 V
load dump −−40 V
battery current on pin BAT Sleep mode; VCC=0V;
V
=12V
BAT
CANH bus line voltage VCC= 0 to 5.5 V;
≥ 0V;
V
BAT
no time limit
CANL bus line voltage VCC= 0 to 5.5 V;
V
≥ 0V;
BAT
no time limit
CANH bus line transmitter voltage drop I
CANH bus line transmitter voltage drop I
= −40 mA −−1.4 V
CANH
=40mA −−1.4 V
CANL
propagation delay TXD to RXD − 1 −µs
bus line output rise time 10 to 90%; C1 = 10 nF − 0.6 −µs
bus line output fall time 90 to 10%; C1 = 1 nF − 0.3 −µs
operating ambient temperature −40 − +125 °C
4.75 − 5.25 V
− 30 50 µA
−40 − +40 V
−40 − +40 V
1999 Feb 11 3
Page 4

Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
BLOCK DIAGRAM
handbook, full pagewidth
WAKE
STB
TXD
ERR
RXD
INH
EN
BAT
14
1
7
5
6
V
CC
2
TIMER
V
CC
4
V
CC
3
WAKE-UP
STANDBY
CONTROL
FAILURE DETECTOR
PLUS WAKE-UP
PLUS TIME-OUT
13
GND
TEMPERATURE
PROTECTION
DRIVER
TJA1054
RECEIVER
V
CC
10
FILTER
FILTER
9
RTL
11
CANH
12
CANL
8
RTH
MGL421
Fig.1 Block diagram.
1999 Feb 11 4
Page 5

Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
PINNING
SYMBOL PIN DESCRIPTION
INH 1 inhibit output for switching an external voltage regulator if a wake-up signal occurs
TXD 2 transmit data input for activating the driver to the bus lines
RXD 3 receive data output for reading out the data from the bus lines
ERR 4 error, wake-up and power-on indication output; active LOW in normal operating mode when the
bus has a failure and in low power modes (wake-up signal or in power-on standby)
STB 5 standby digital control signal input (active LOW); defines together with input signal on pin EN the
state of the transceiver (in normal and low power modes); see Table 2 and Fig.3
EN 6 enable digital control signal input; defines together with input signal on pin
transceiver (in normal and low power modes); see Table 2 and Fig.3
WAKE 7 local wake-up signal input; falling and rising edges are both detected
RTH 8 termination resistor connection; in case of a CANH bus wire error the line is terminated with a
selectable impedance
RTL 9 termination resistor connection; in case of a CANL bus wire the line is terminated with a
selectable impedance
V
CC
10 supply voltage
CANH 11 HIGH-level voltage bus line
CANL 12 LOW-level voltage bus line
GND 13 ground
BAT 14 battery supply
STB the state of the
handbook, halfpage
1INH
2
TXD GND
3
RXD CANL
4
ERR CANH
STB V
EN RTL
WAKE RTH
TJA1054T
5
6
7
Fig.2 Pin configuration.
1999 Feb 11 5
MGL422
14 BAT
13
12
11
10
CC
9
8
Page 6

Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
FUNCTIONAL DESCRIPTION
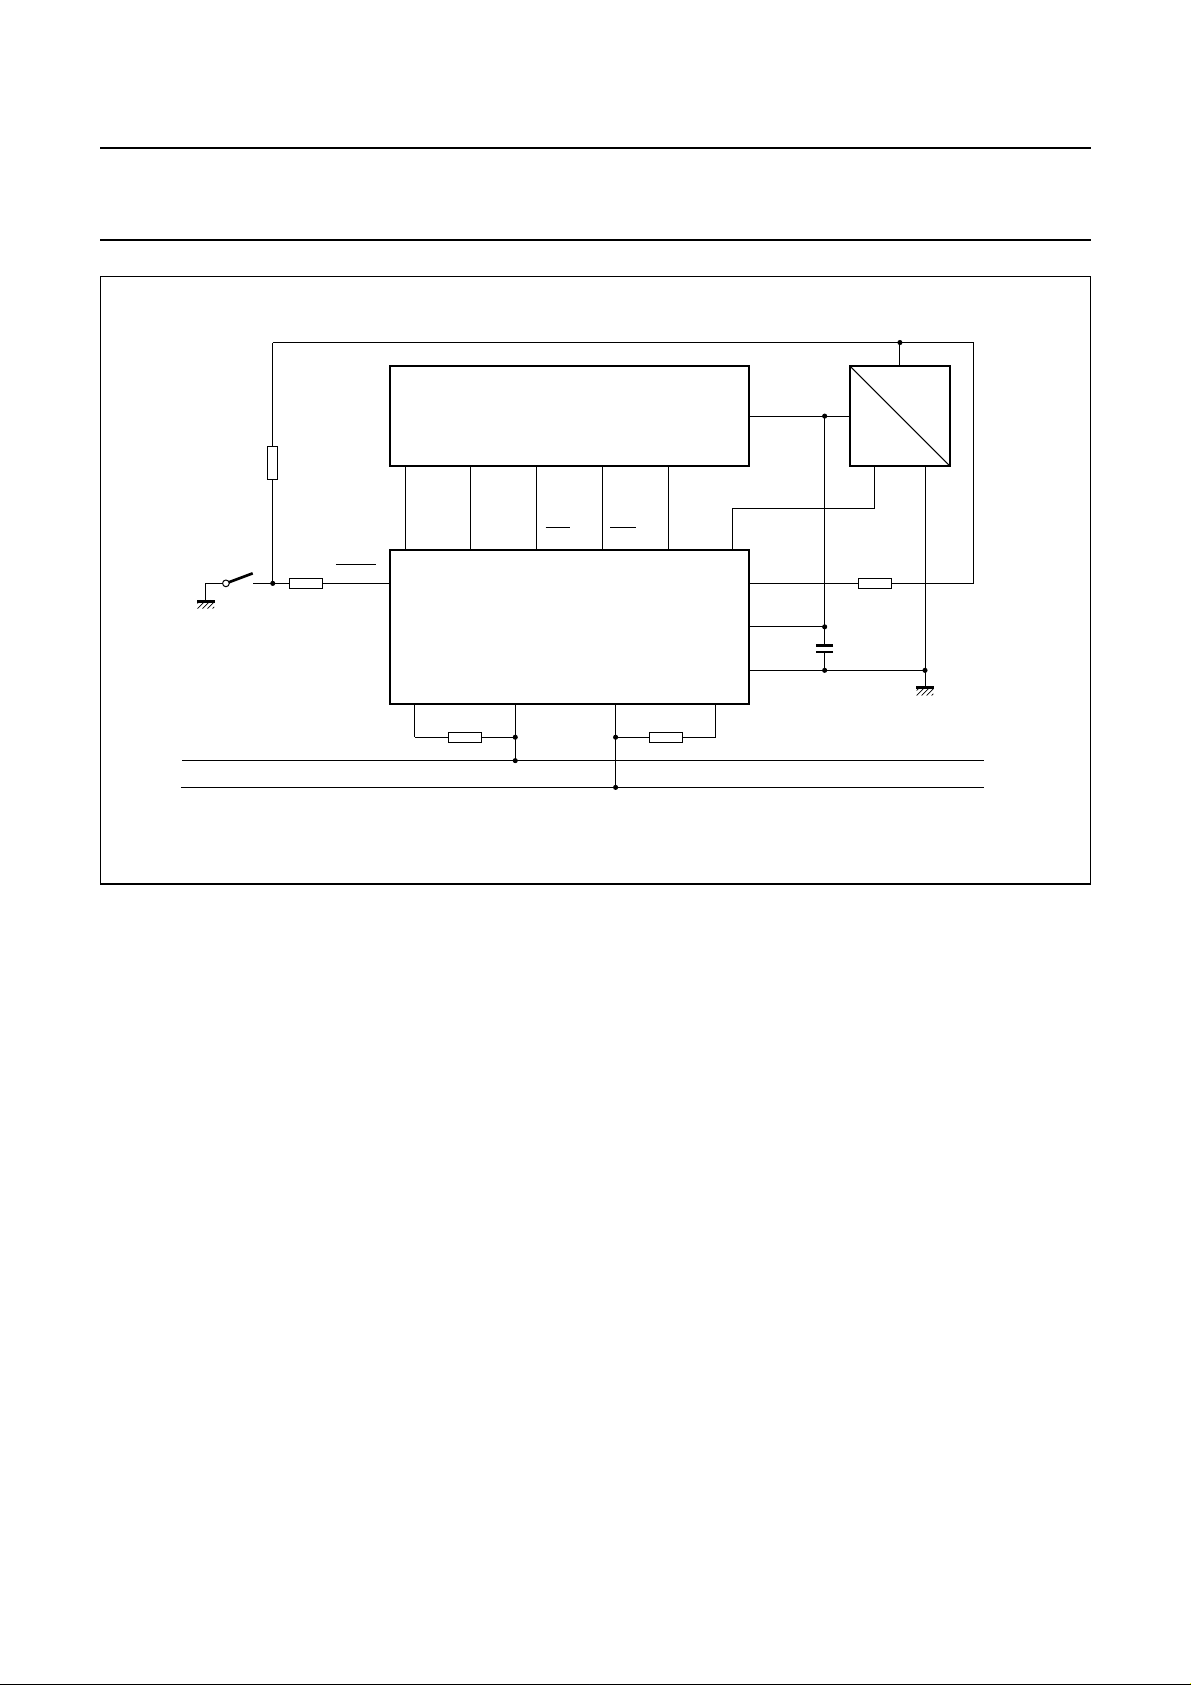
The TJA1054 is the interface between the CAN protocol
controller and the physical wires of the CAN bus
(see Fig.7). It is primarily intended for low speed
applications, up to 125 kBaud, in passenger cars.
The device provides differential transmit capability to the
CAN bus and differential receive capability to the CAN
controller.
To reduce RFI, the rise and fall slope are limited. This
allows the use of an unshielded twisted pair or a parallel
pair of wires for the bus lines. Moreover, it supports
transmission capability on either bus line if one of the wires
is corrupted. The failure detection logic automatically
selects a suitable transmission mode.
In normal operating mode (no wiring failures) the
differential receiver is output on pin RXD (see Fig.1).
The differential receiver inputs are connected to
pins CANH and CANL through integrated filters.
The filtered input signals are also used for the single-wire
receivers. The receivers connected to pins CANH
and CANL have threshold voltages that ensure a
maximum noise margin in single-wire mode.
A timer has been integrated at pin TXD. This timer
prevents the TJA1054 from driving the bus lines to a
permanent dominant state.
Failure detector
The failure detector is fully active in the normal operating
mode. After the detection of a single bus failure the
detector switches to the appropriate mode (see Table 1).
Table 1 Bus failures
FAILURE DESCRIPTION
1 CANH wire interrupted
2 CANL wire interrupted
3 CANH short-circuited to battery
3a CANH short-circuited to V
4 CANL short-circuited to ground
5 CANH short-circuited to ground
6 CANL short-circuited to battery
6a CANL short-circuited to V
7 CANL mutually short-circuited to CANH
CC
CC
The differential receiver threshold voltage is set at
−3.2 V typically (VCC= 5 V). This ensures correct
reception with a noise margin as high as possible in the
normal operating mode and in the event of failures 1, 2,
4 and 6a. These failures, or recovery from them, do not
destroy ongoing transmissions.
Failures 3 and 6 are detected by comparators connected
to the CANH and CANL bus lines, respectively. If the
comparator threshold is exceeded for a certain period of
time, the reception is switched to the single-wire mode.
This time is needed to avoid false triggering by external RF
fields. Recovery from these failures is detected
automatically after a certain time-out (filtering) and no
transmission is lost. In the event of failure 3 the CANH
driver and pin RTH are switched off. In the event of
failure 6 the CANL driver and pin RTL are switched off.
The pull-up current on pin RTL and the pull-down current
on pin RTH will not be switched off.
Failures 3a, 4 and 7 initially result in a permanent
dominant level on pin RXD. After a time-out, the CANL
driver and pin RTL are switched off (failures 4 and 7) or
the CANH driver and pin RTH are switched off (failure 3a).
Only a weak pull-up on pin RTL or a weak pull-down on
pin RTH remains. Reception continues by switching to the
single-wire mode via pins CANH or CANL. When
failures 3a, 4 or 7 are removed, the recessive bus levels
are restored. If the differential voltage remains below the
recessive threshold level for a certain period of time,
reception and transmission switch back to the differential
mode.
If any of the wiring failure occurs, the output signal on
pin ERR will become LOW. On error recovery, the output
signal on pin ERR will become HIGH again.
During all single-wire transmissions, the EMC
performance (both immunity and emission) is worse than
in the differential mode. The integrated receiver filters
suppress any HF noise induced into the bus wires.
The cut-off frequency of these filters is a compromise
between propagation delay and HF suppression. In the
single-wire mode, LF noise cannot be distinguished from
the required signal.
1999 Feb 11 6
Page 7
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
is provided the wake-up request can be read on the
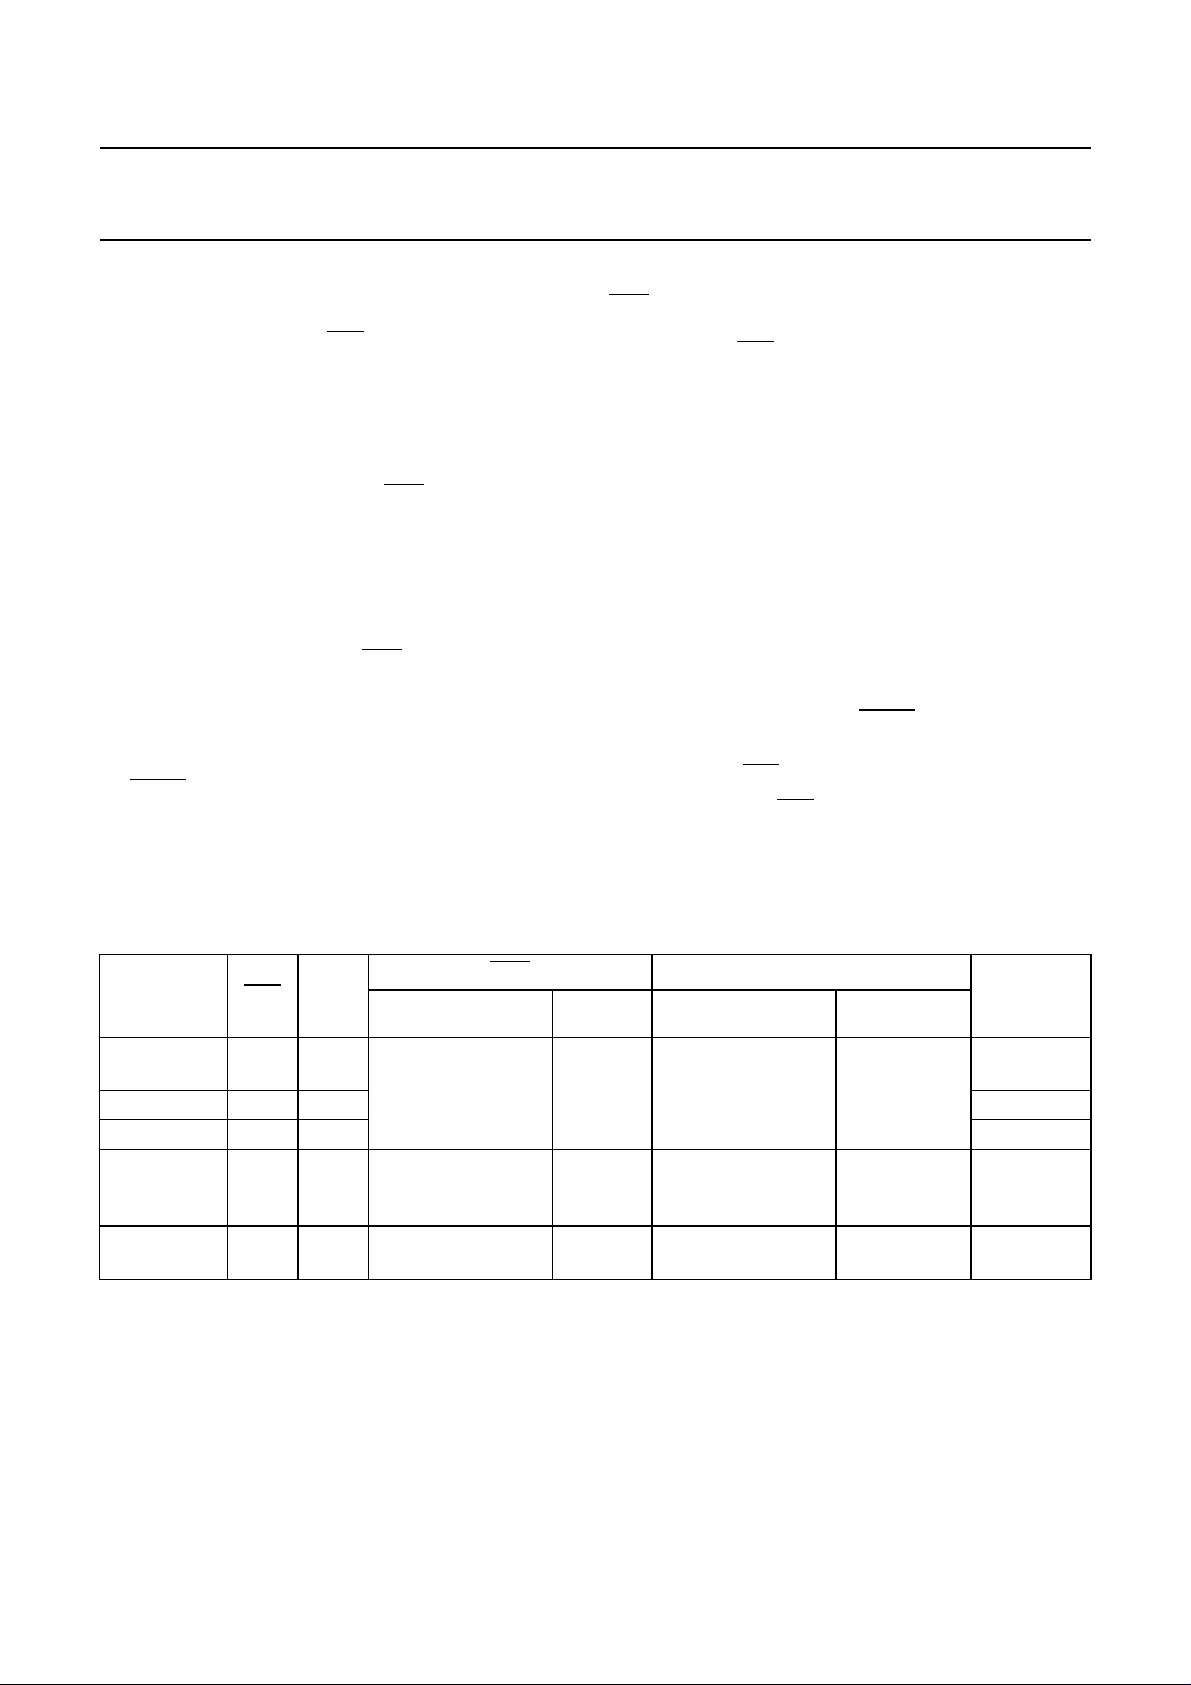
Low power modes
The transceiver provides 3 low power modes which can be
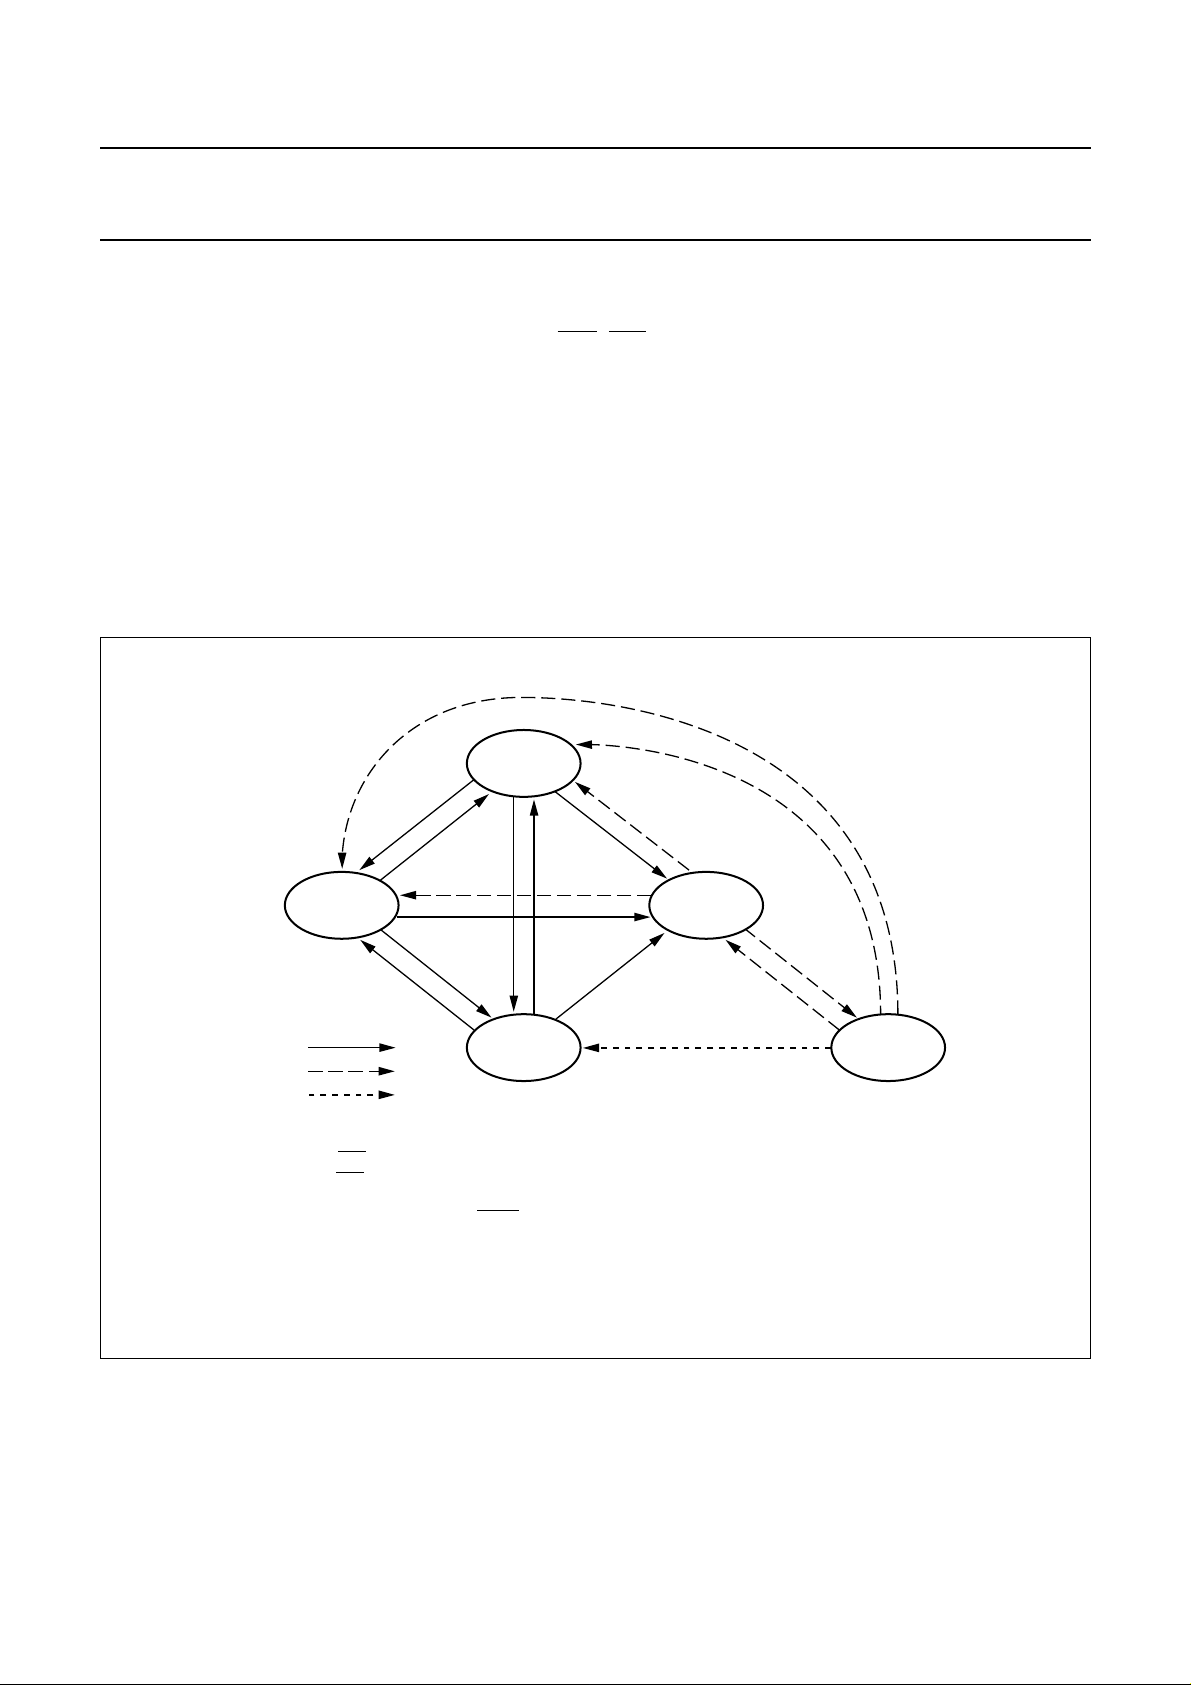
entered and exited via pins STB and EN (see Table 2 and
Fig.3).
The Sleep mode is the mode with the lowest power
consumption. Pin INH is switched to high-impedance for
deactivation of the external voltage regulator. Pin CANL is
biased to the battery voltage via pin RTL. If the supply
voltage is provided pins RXD and ERR will signal the
wake-up interrupt signal.
The standby mode will react the same as the Sleep mode
but with a HIGH-level on pin INH.
The power-on standby mode is the same as the standby
mode with the battery power-on flag instead of the
wake-up interrupt signal on pin
ERR. The output on
pin RXD will show the wake-up interrupt. This mode is only
for reading out the power-on flag.
Wake-up requests are recognized by the transceiver when
a dominant signal is detected on either bus line or if
pin WAKE detects an edge (rising or falling) which stays
longer HIGH or LOW respectively during a certain period
of time. On a wake-up request the transceiver will set the
output on pin INH which can be used to activate the
external supply voltage regulator.
If V
CC
ERR or RXD outputs, so the external microcontroller can
wake-up the transceiver (switch to normal operating
mode) via pins STB and EN.
To prevent false wake-up due to transients or RF fields,
the wake-up voltage levels have to be maintained for a
certain period of time. In the low power modes the failure
detection circuit remains partly active to prevent an
increased power consumption in the event of
failures 3, 3a, 4 and 7.
Pin INH is set to floating only during the goto-sleep
command and stays floating during the Sleep mode. If
pin INH is set to floating, pin INH will not be set to
HIGH-level again just by a mode change to normal
operating mode. Pin INH will be set to HIGH-level by the
following events only:
• power-on (V
switching-on at cold start)
BAT
• rising or falling edge on pin WAKE
• a message with 5 consecutive dominant bits during
pin EN or pin STB is at LOW-level.
The signals on pins STB and EN will internally be set to
LOW-level when VCC is below a certain threshold voltage
so providing fail safe functionality.
Table 2 Normal operating and low power modes
ERR RXD RTL
MODE
STB EN
SWITCHED
LOW HIGH LOW HIGH
Goto-sleep
command
Sleep 0 0
01
wake-up interrupt
signal;
(1)
notes 2 and 3
wake-up interrupt
signal;
notes 2 and 3
Standby 0 0 V
Power-on
standby
10V
power-on flag;
BAT
notes 2 and 4
wake-up interrupt
signal;
notes 2 and 3
Normal
operating
1 1 error flag no error
flag
dominant
received data
recessive
received data
Notes
1. In case the goto-sleep command was used before. When V
drops pin EN will become LOW, but this does not effect
CC
the internal functions due to the fail safe functionality.
2. If the supply voltage VCC is present.
3. Wake-up interrupts are released when entering the normal operating mode.
4. V
power-on flag will be reset when entering the normal operating mode.
BAT
V
V
V
TO
V
BAT
BAT
BAT
BAT
CC
1999 Feb 11 7
Page 8
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
Power-on
After power-on (V
switched on) the signal on pin INH will become HIGH and an internal power-on flag will be set. This
BAT
flag can be read in the power-on standby mode via pin ERR (STB = 1; EN = 0) and will be reset by entering the normal
operating mode.
Protections
A current limiting circuit protects the transmitter output stages against short-circuit to positive and negative battery
voltage.
If the junction temperature exceeds a maximum value, the transmitter output stages are disabled. Because the
transmitter is responsible for the major part of the power dissipation, this will result in a reduced power dissipation and
hence a lower chip temperature. All other parts of the IC will remain operating.
The pins CANH and CANL are protected against electrical transients which may occur in an automotive environment.
handbook, full pagewidth
POWER-ON
STANDBY
10
NORMAL
11
(4)
GOTO
(5)
SLEEP
01
(1)
(2)
(3)
(1) Mode change via input ports STB and EN.
(2) Mode change via input ports STB and EN, but in the sleep mode INH is inactive and possibly there is no VCC.
Mode control is only possible if V
(3) INH is activated after wake-up via bus or input port WAKE.
(4) Transitions to normal mode clear the internal wake-up: interrupt and battery fail flag are cleared.
(5) Transitions to sleep mode: INH is deactivated.
of the transceiver is active.
CC
STANDBY
00
Fig.3 Mode control.
1999 Feb 11 8
SLEEP
00
MBK949
Page 9
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
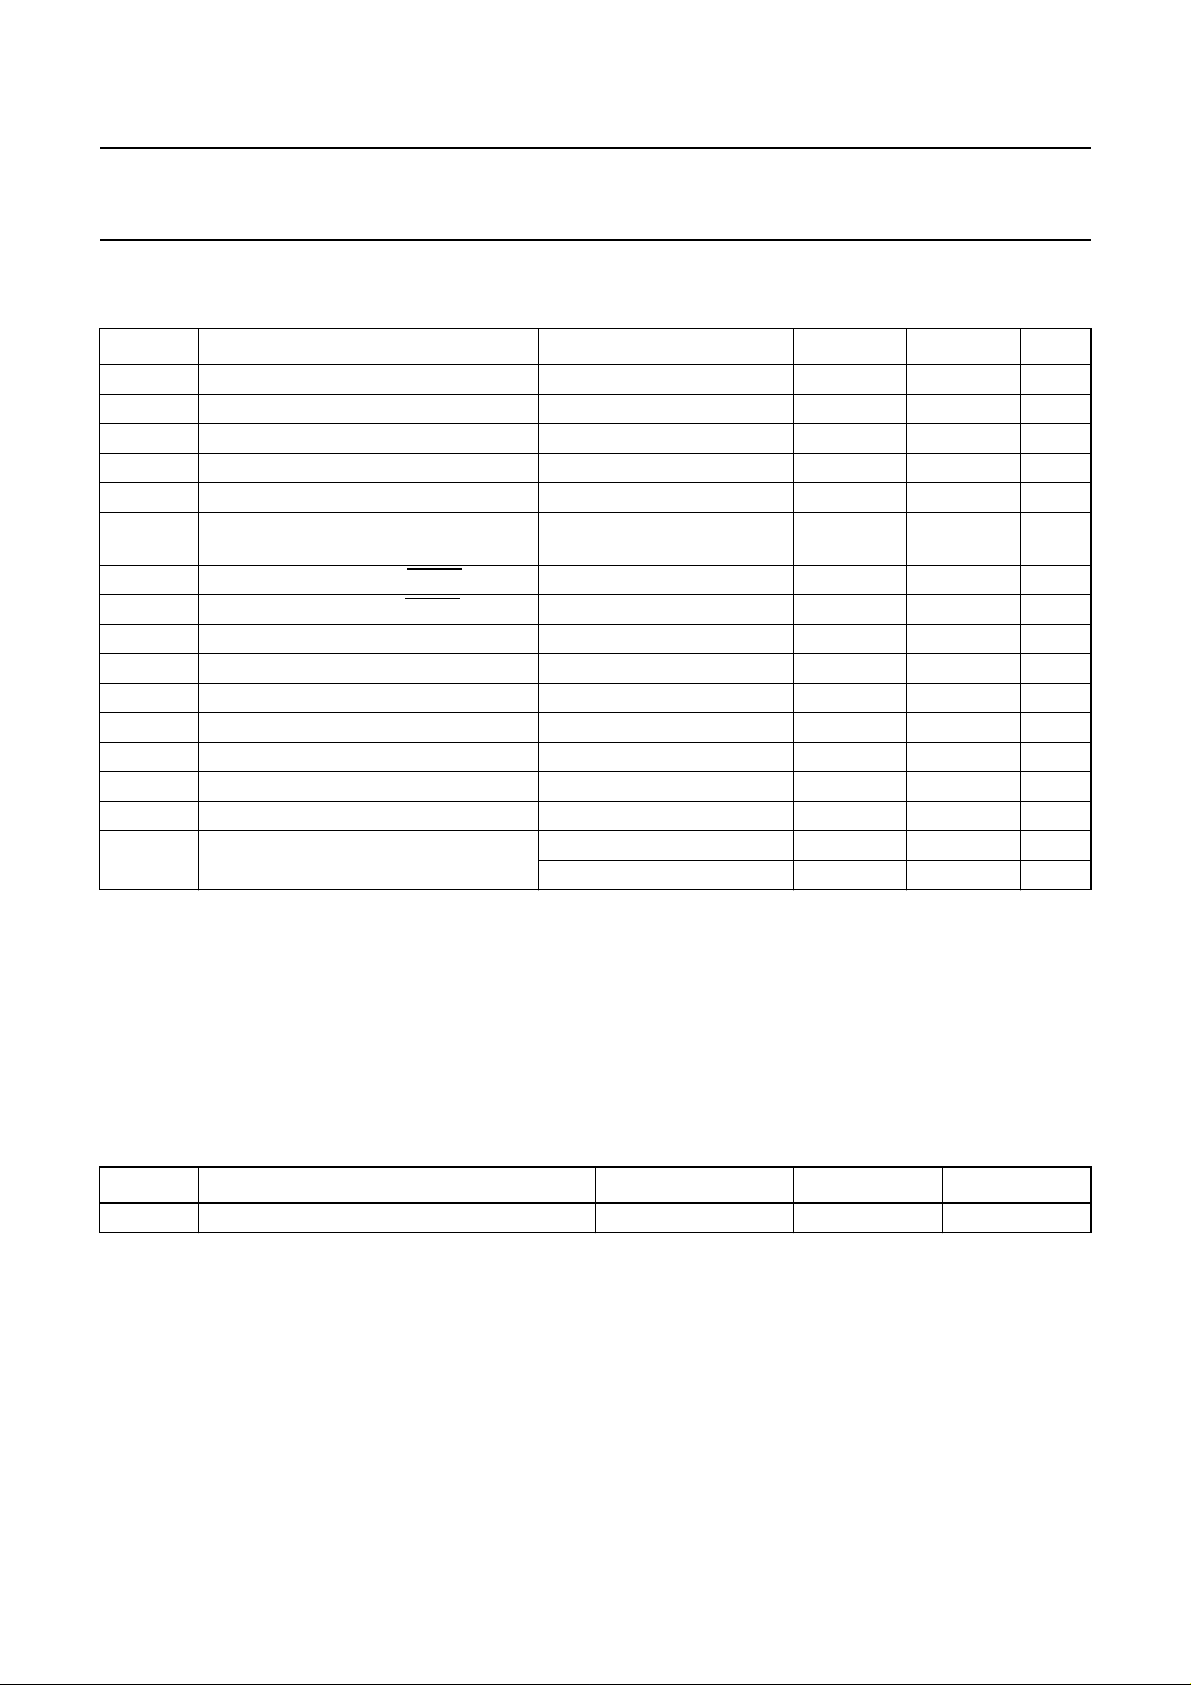
LIMITING VALUES
In accordance with the Absolute Maximum Rating System (IEC 134); note 1.
SYMBOL PARAMETER CONDITIONS MIN. MAX. UNIT
V
CC
V
BAT
V
n
V
CANH
V
CANL
V
trt(n)
V
WAKE
I
WAKE
V
INH
V
RTH
V
RTL
R
RTH
R
RTL
T
vj
T
stg
V
esd
supply voltage on pin V
CC
−0.3 +6 V
battery voltage on pin BAT −0.3 +40 V
DC voltage on pins 2 to 6 −0.3 VCC+ 0.3 V
DC voltage on pin CANH −40 +40 V
DC voltage on pin CANL −40 +40 V
transient voltage on
see Fig.6 −150 +100 V
pins CANH and CANL
DC input voltage on pin WAKE − V
+ 0.3 V
BAT
DC input current on pin WAKE −15 − mA
DC output voltage on pin INH −0.3 V
DC voltage on pin RTH −0.3 V
DC voltage on pin RTL −0.3 V
+ 0.3 V
BAT
+ 1.2 V
BAT
+ 1.2 V
BAT
termination resistance on pin RTH 500 16000 Ω
termination resistance on pin RTL 500 16000 Ω
virtual junction temperature note 2 −40 +150 °C
storage temperature −55 +150 °C
electrostatic discharge voltage human body model; note 3 −2.0 +2.0 kV
machine model; note 4 −200 +200 V
Notes
1. All voltages are defined with respect to pin GND. Positive current flows into the IC.
2. Junction temperature in accordance with
R
is a fixed value to be used for the calculation of Tvj. The rating for Tvj limits the allowable combinations of
th(vj-a)
power dissipation (P) and operating ambient temperature (T
“IEC 747-1”
. An alternative definition is: Tvj=T
).
amb
amb
+P×R
th(vj-a)
3. Equivalent to discharging a 100 pF capacitor through a 1.5 kΩ resistor.
4. Equivalent to discharging a 200 pF capacitor through a 10 Ω resistor and a 0.75 µH coil.
THERMAL CHARACTERISTICS
SYMBOL PARAMETER CONDITIONS VALUE UNIT
R
th(vj-a)
thermal resistance from junction to ambient in free air 120 K/W
QUALITY SPECIFICATION
Quality specification in accordance with
“SNW-FQ-611-Part-E”
.
where
1999 Feb 11 9
Page 10
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
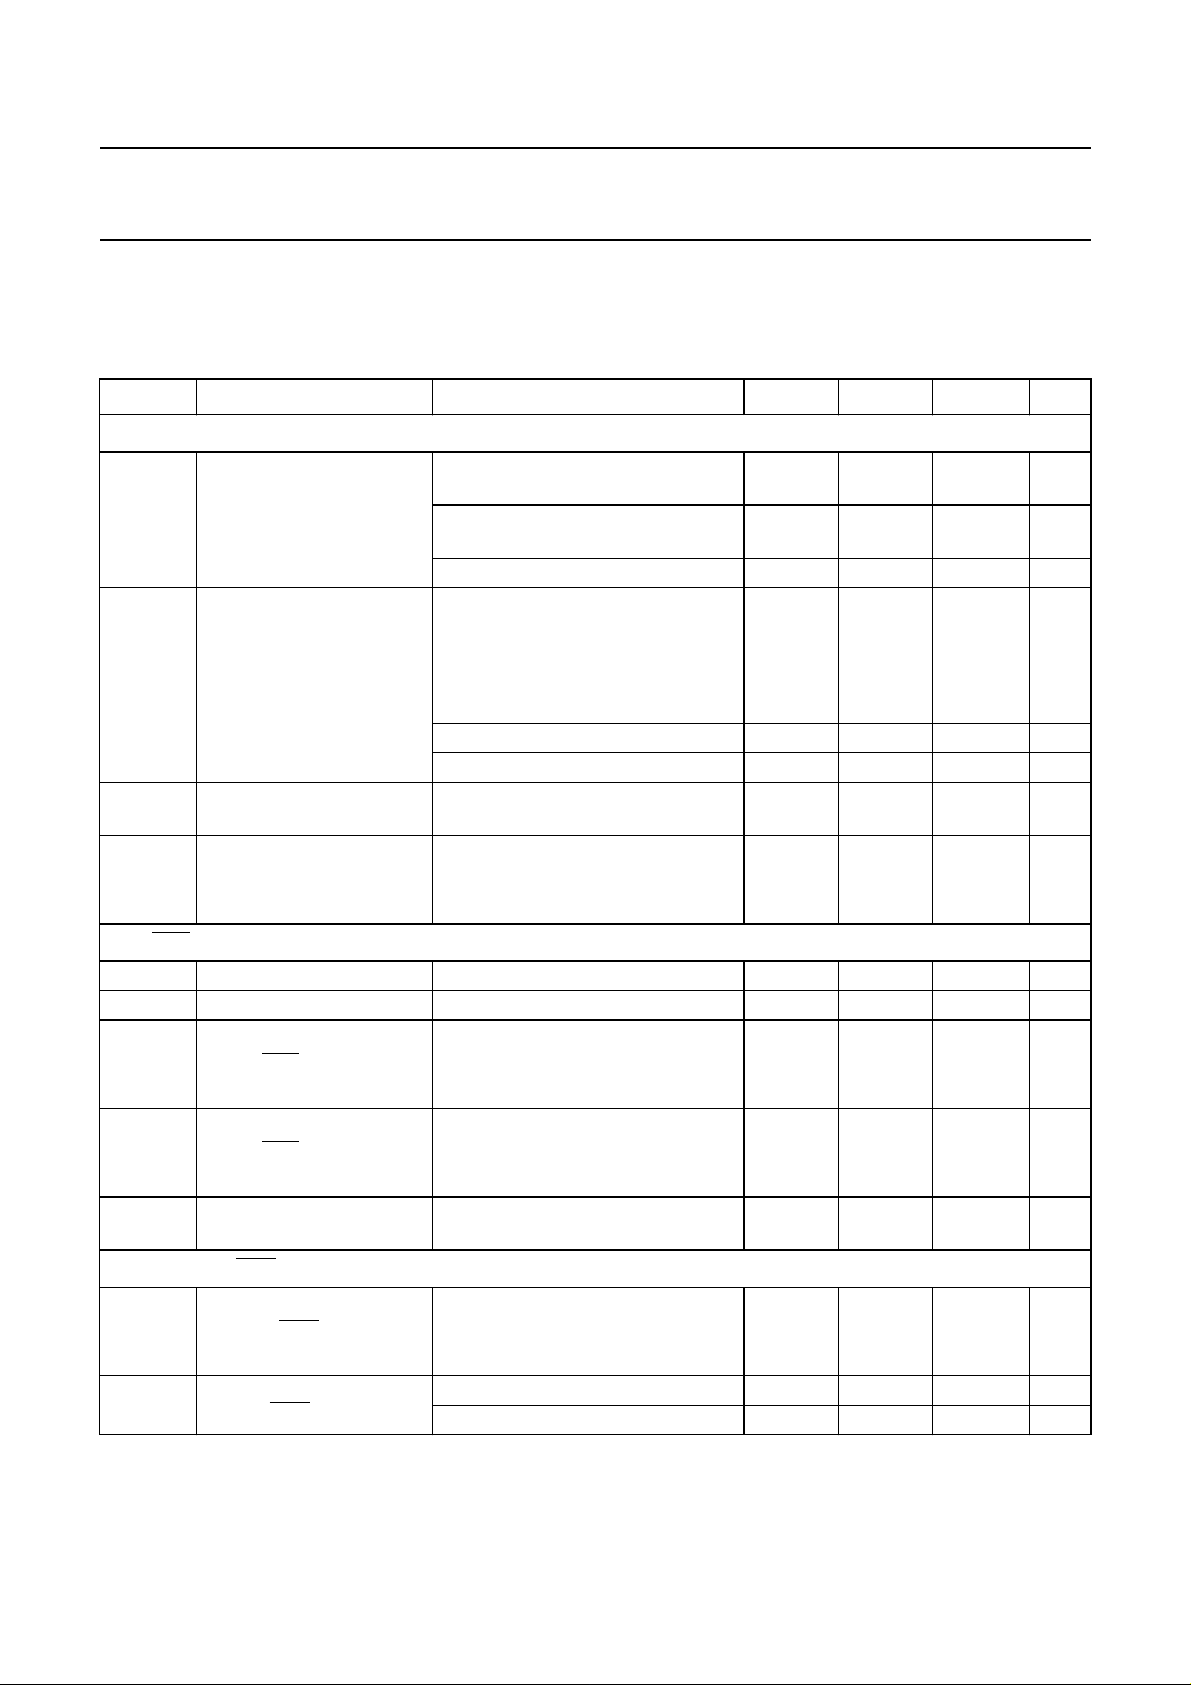
DC CHARACTERISTICS
V
= 4.75 to 5.25 V; V
CC
defined with respect to ground. Positive currents flow into the IC. All parameters are guaranteed over the temperature
range by design, but only 100% tested at 25 °C.
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
Supplies
I
CC
I
BAT
I
CC+IBAT
supply current normal operating mode;
battery current on pin BAT all modes; in low power modes at
supply current plus battery
current
V
BAT
battery voltage on pin BAT low power modes
= 5 to 27 V; V
BAT
; T
STB=VCC
= −40 to +125 °C; unless otherwise specified. All voltages are
amb
4711mA
V
TXD=VCC
normal operating mode;
V
TXD
low power modes; V
V
RTL=VBAT
V
RTL
V
BAT=VWAKE=VINH
V
BAT=VWAKE=VINH
V
BAT=VWAKE=VINH
V
BAT=VWAKE=VINH
low power modes; VCC=5V;
V
BAT=VWAKE=VINH
(recessive)
= 0 V (dominant); no load
TXD=VCC
or
< 2.5 V (>1.5 ms)
= 12 V 10 30 50 µA
= 5 to 27 V 5 30 125 µA
= 3.5 V 5 20 30 µA
=1V 0 0 10 µA
=12V
11 17 27 mA
0010µA
− 35 60 µA
for setting power-on flag −−1V
for not setting power-on flag 3.5 −−V
Pins
STB, EN and TXD
V
IH
V
IL
I
IH
I
IL
V
CC
HIGH-level input voltage 0.7V
LOW-level input voltage −0.3 − 0.3V
HIGH-level input current VI=4V
LOW-level input current VI=1V
supply voltage for forced power-on standby mode
Pins RXD and
V
OH
V
OL
HIGH-level output voltage
LOW-level output voltage
on pins ERR and RXD
− VCC+ 0.3 V
CC
V
CC
pins
STB and EN − 920µA
pin TXD −25 −80 −200 µA
pins
STB and EN 4 8 −µA
pin TXD −100 −320 −800 µA
2.75 − 4.5 V
(fail safe)
ERR
ERR lO= −100 µAV
on pin
on pin RXD I
= −1mA VCC− 0.9 − V
O
− 0.9 − V
CC
CC
CC
V
V
IO= 1.6 mA 0 − 0.4 V
= 7.5 mA 0 − 1.5 V
I
O
1999 Feb 11 10
Page 11
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
Pin WAKE
I
IL
V
th(WAKE)
LOW-level input current V
wake-up threshold voltage V
Pin INH
∆V
H
leakage current Sleep mode; V
I
L
HIGH-level voltage drop I
Pins CANH and CANL
V
diff
differential receiver
threshold voltage
V
O(reces)
recessive output voltage V
on pin CANH R
on pin CANL R
V
O(dom)
dominant output voltage V
on pin CANH I
on pin CANL I
I
O(CANH)
output current on
pin CANH
I
O(CANL)
output current on
pin CANL
V
det(CANH)
detection threshold
voltage for short-circuit to
battery voltage on
pin CANH
V
det(CANL)
detection threshold
voltage for short-circuit to
battery voltage on
pin CANL
V
th(wake)
wake-up threshold voltage
on pin CANL low power modes 2.5 3.2 3.9 V
on pin CANH low power modes 1.1 1.8 2.5 V
∆V
th(wake)
difference of wake-up
threshold voltages
V
se(CANH)
single-ended receiver
threshold voltage on
pin CANH
=0V; V
WAKE
= 0 V 2.5 3.2 3.9 V
STB
= −0.18 mA −−0.8 V
INH
=27V −1 −4 −10 µA
BAT
=0V −−5µA
INH
no failures and
bus failures 1, 2, 5, 6a; see Fig.4
V
=5V −3.5 −3.2 −2.9 V
CC
= 4.75 to 5.25 V −0.70VCC−0.64VCC−0.58VCCV
V
CC
TXD=VCC
<4kΩ−−0.2 V
RTH
<4kΩ VCC− 0.2 −−V
RTL
=0V; VEN=V
TXD
= −40 mA VCC− 1.4 −−V
CANH
=40mA −−1.4 V
CANL
normal operating mode;
V
=0V; V
CANH
low power modes;
=0V;VCC=5V
V
CANH
normal operating mode;
V
= 14 V; V
CANL
low power modes;
=12V;V
V
CANL
TXD
TXD
BAT
CC
−45 −80 −110 mA
=0V
−−0.25 −µA
45 70 100 mA
=0V
− 0 −µA
=12V
normal operating mode 1.5 1.7 1.85 V
low power modes 1.1 1.8 2.5 V
normal operating mode 6.5 7.3 8 V
low power modes 0.8 1.4 − V
normal operating mode and
failures 4, 6 and 7
= 5 V 1.5 1.7 1.85 V
V
CC
V
= 4.75 to 5.25 V 0.30V
CC
CC
0.34V
CC
0.37V
CC
V
1999 Feb 11 11
Page 12
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
V
se(CANL)
Pins RTH and RTL
R
sw(RTL)
R
sw(RTH)
V
O(RTH)
I
O(RTL)
I
pu(RTL)
I
pd(RTH)
single-ended receiver
threshold voltage on
pin CANL
switch-on resistance
between pin RTL and V
switch-on resistance
between pin RTH and
normal operating mode and
failures 3 and 3a
V
= 5 V 3.15 3.3 3.45 V
CC
V
= 4.75 to 5.25 V 0.63V
CC
normal operating mode;
IO <10mA
CC
normal operating mode;
<10mA
I
O
CC
0.66V
CC
0.69V
CC
− 50 100 Ω
− 50 100 Ω
ground
output voltage on pin RTH low power modes; IO=1mA − 0.7 1.0 V
output current on pin RTL low power modes; V
pull-up current on pin RTL normal operating mode and
=0V −1.25 −0.65 −0.3 mA
RTL
− 75 −µA
failures 4, 6 and 7
pull-down current on
pin RTH
normal operating mode and
failures 3 and 3a
− 75 −µA
V
Thermal shutdown
T
j
junction temperature for shutdown 155 165 180 °C
1999 Feb 11 12
Page 13
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
TIMING CHARACTERISTICS
V
= 4.75 to 5.25 V; V
CC
defined with respect to ground. Positive currents flow into the IC. All parameters are guaranteed over the temperature
range by design, but only 100% tested at 25 °C.
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
t
t(r-d)
CANL and CANH output
transition time for
recessive-to-dominant
t
t(d-r)
CANL and CANH output
transition time for
dominant-to-recessive
t
PD(L)
propagation delay TXD to
RXD (LOW)
t
PD(H)
propagation delay TXD to
RXD (HIGH)
t
CANH(min)
minimum dominant time for
wake-up on pin CANH
t
CANL(min)
minimum dominant time for
wake-up on pin CANL
t
WAKE(min)
t
det
minimum time on pin WAKE low power modes; V
failure detection time normal mode
= 5 to 27 V; V
BAT
; T
STB=VCC
= −40 to +125 °C; unless otherwise specified. All voltages are
amb
10 to 90%;
C1 = 10 nF; C2 = 0; R1 = 100 Ω;
see Fig.5
10 to 90%;
C1 = 1 nF; C2 = 0; R1 = 100 Ω;
see Fig.5
no failures and failures 1, 2, 5, 6a;
see Figs 4 and 5
C1 = 1 nF; C2 = 0; R1 = 100 Ω− 0.75 1.35 µs
C1 = C2 = 3.3 nF; R1 = 100 Ω− 1 1.75 µs
failures 3, 3a, 4, 6 and 7;
see Figs 4 and 5
C1 = 1 nF; C2 = 0; R1 = 100 Ω− 0.85 1.4 µs
C1 = C2 = 3.3 nF; R1 = 100 Ω− 1.1 1.7 µs
no failures and failures 1, 2, 5, 6a;
see Figs 4 and 5
C1 = 1 nF; C2 = 0; R1 = 100 Ω− 1.2 1.9 µs
C1 = C2 = 3.3 nF; R1 = 100 Ω− 2.5 3.3 µs
failures 3, 3a, 4, 6 and 7;
see Figs 4 and 5
C1 = 1 nF; C2 = 0; R1 = 100 Ω− 1.1 1.7 µs
C1 = C2 = 3.3 nF; R1 = 100 Ω− 1.5 2.2 µs
low power modes; V
low power modes; V
BAT
BAT
BAT
for wake-up after receiving a falling
or rising edge
failure 3 and 3a 1.6 − 8.0 ms
failure 4, 6 and 7 0.3 − 1.6 ms
low power modes; V
BAT
failure 3 and 3a 1.6 − 8.0 ms
failure 4 and 7 0.1 − 1.6 ms
0.35 0.60 −µs
0.2 0.3 −µs
=12V 7 − 38 µs
=12V 7 − 38 µs
=12V;
7 − 38 µs
=12V
1999 Feb 11 13
Page 14
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
t
rec
t
h(min)
t
dis(TXD)
∆pc pulse-count difference between
failure recovery time normal mode
failure 3 and 3a 0.3 − 1.6 ms
failure 4 and 7 7 − 38 µs
failure 6 125 − 750 µs
low power modes; V
failures 3, 3a, 4 and 7 0.3 − 1.6 ms
minimum hold time of goto-sleep
command
disable time of TXD permanent
normal mode; V
dominant timer
normal mode and
CANH and CANL
failures 1, 2, 5 and 6a
failure detection
(pin ERR becomes LOW)
failure recovery − 4 −
=12V
BAT
5 − 50 µs
= 0 V 0.75 − 4ms
TXD
− 4 −
handbook, full pagewidth
V
diff=VCANH
− V
V
V
CANL
V
TXD
CANL
CANH
V
diff
V
RXD
.
t
PD(L)
t
PD(H)
MGL424
V
CC
0 V
5 V
3.6 V
1.4 V
0 V
2.2 V
−3.2 V
−5 V
0.7V
0.3V
CC
CC
Fig.4 Timing diagram for dynamic characteristics.
1999 Feb 11 14
Page 15
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
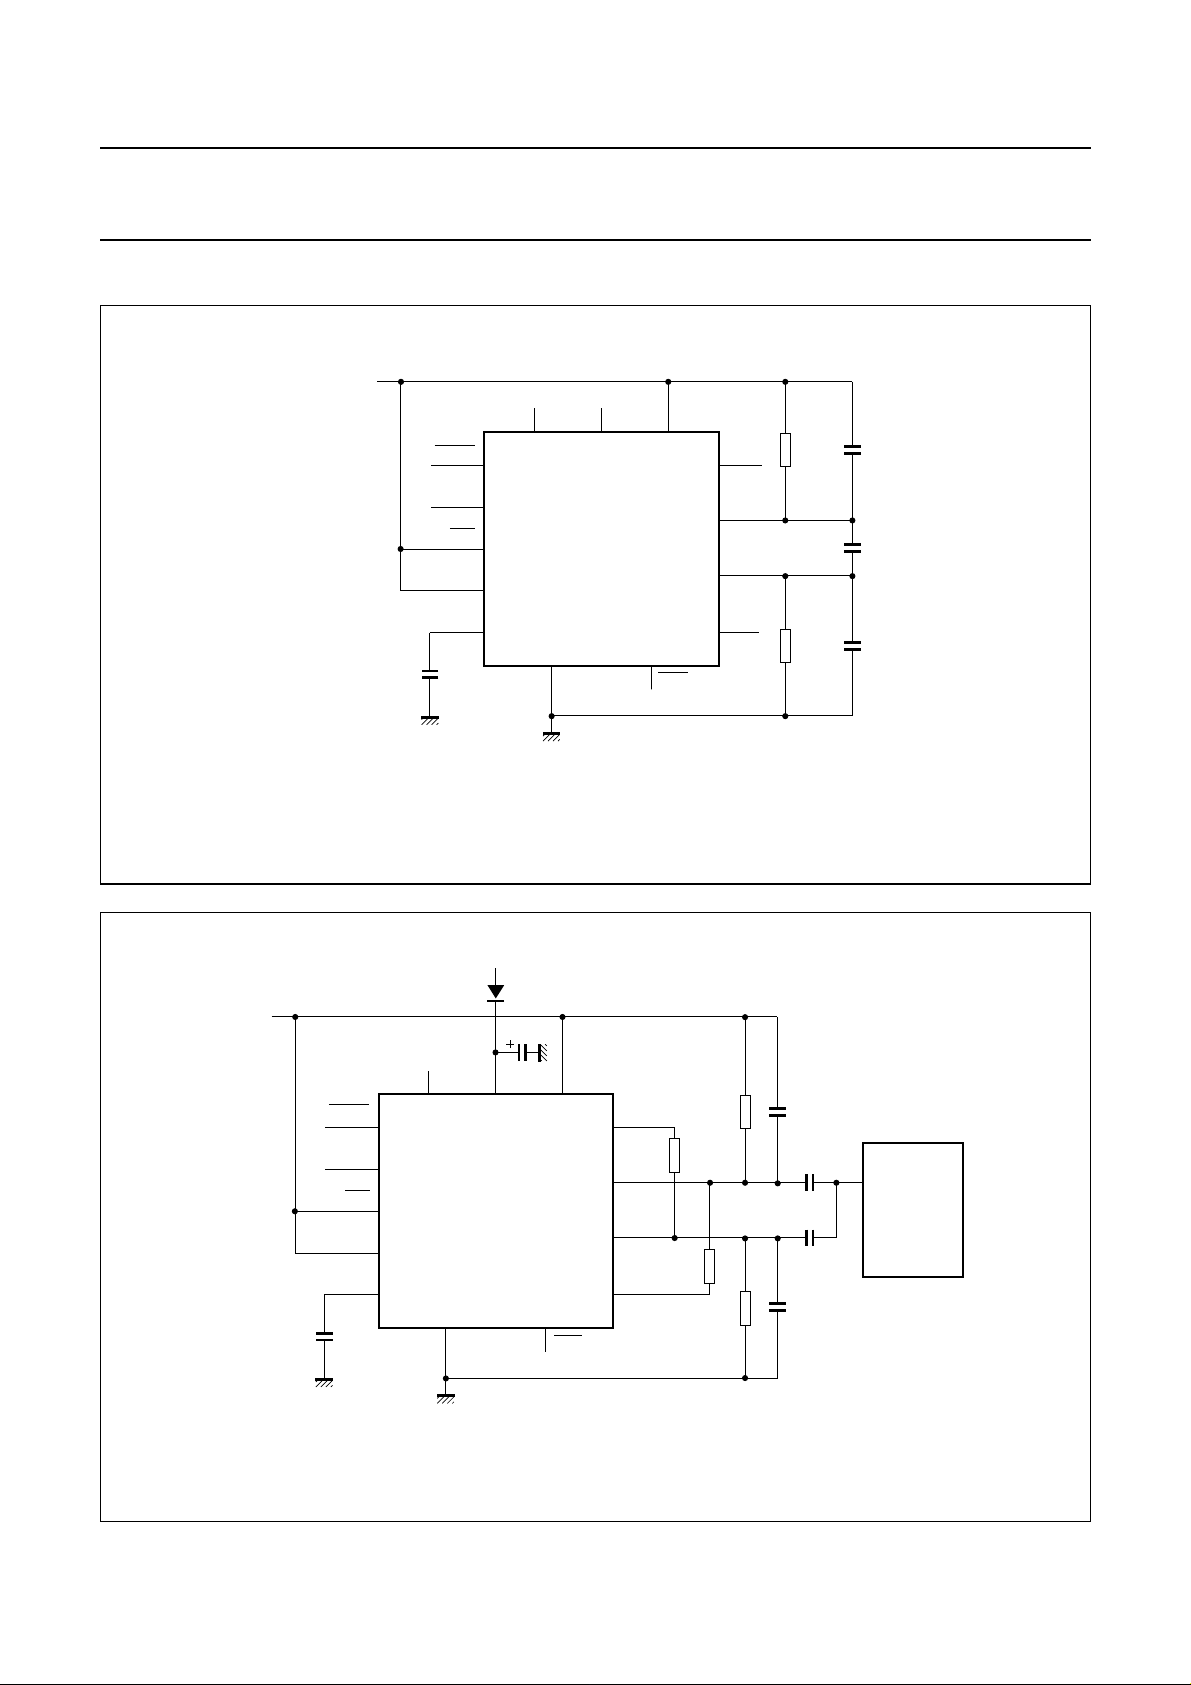
TEST AND APPLICATION INFORMATION
+
handbook, full pagewidth
5 V
20 pF
WAKE
TXD
STB
EN
RXD
INH BAT
11410
7
2
5
6
3
TJA1054
13 4
GND ERR
V
CC
RTH
8
CANL
12
CANH
11
RTL
9
R1 C1
C2
R1 C1
MGL423
For testing, the 100 Ω termination resistors are not connected to RTH or RTL because minimum 500 Ω per transceiver is allowed.
Fig.5 Test circuit for dynamic characteristics.
+
handbook, full pagewidth
+
5 V
WAKE
TXD
STB
EN
RXD
20 pF
11410
7
2
5
6
3
12 V
10 µF
INH BAT
TJA1054
13 4
GND ERR
V
CC
RTH
8
CANL
12
CANH
11
RTL
9
125 Ω
511 Ω
511 Ω
125 Ω
1 nF
1 nF
1 nF
1 nF
GENERATOR
MGL426
The waveforms of the applied transients will be in accordance with ISO 7637 part 1, test pulses 1, 2, 3a and 3b.
Fig.6 Test circuit for automotive transients.
1999 Feb 11 15
Page 16
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
handbook, full pagewidth
WAKE
P8xC592/P8xCE598
CAN CONTROLLER
CTX0 CRXO Px.x Px.x Px.x
TXD RXD STB ERR EN INH
2
7
35461
TJA1054
CAN TRANSCEIVER
811129
CAN BUS LINE
V
BAT
14
V
10
GND
13
RTLCANLCANHRTH
Fig.7 Application diagram.
DD
CC
V
BAT
+
5 V
BATTERY
+5 V
100 nF
MGL425
1999 Feb 11 16
Page 17
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
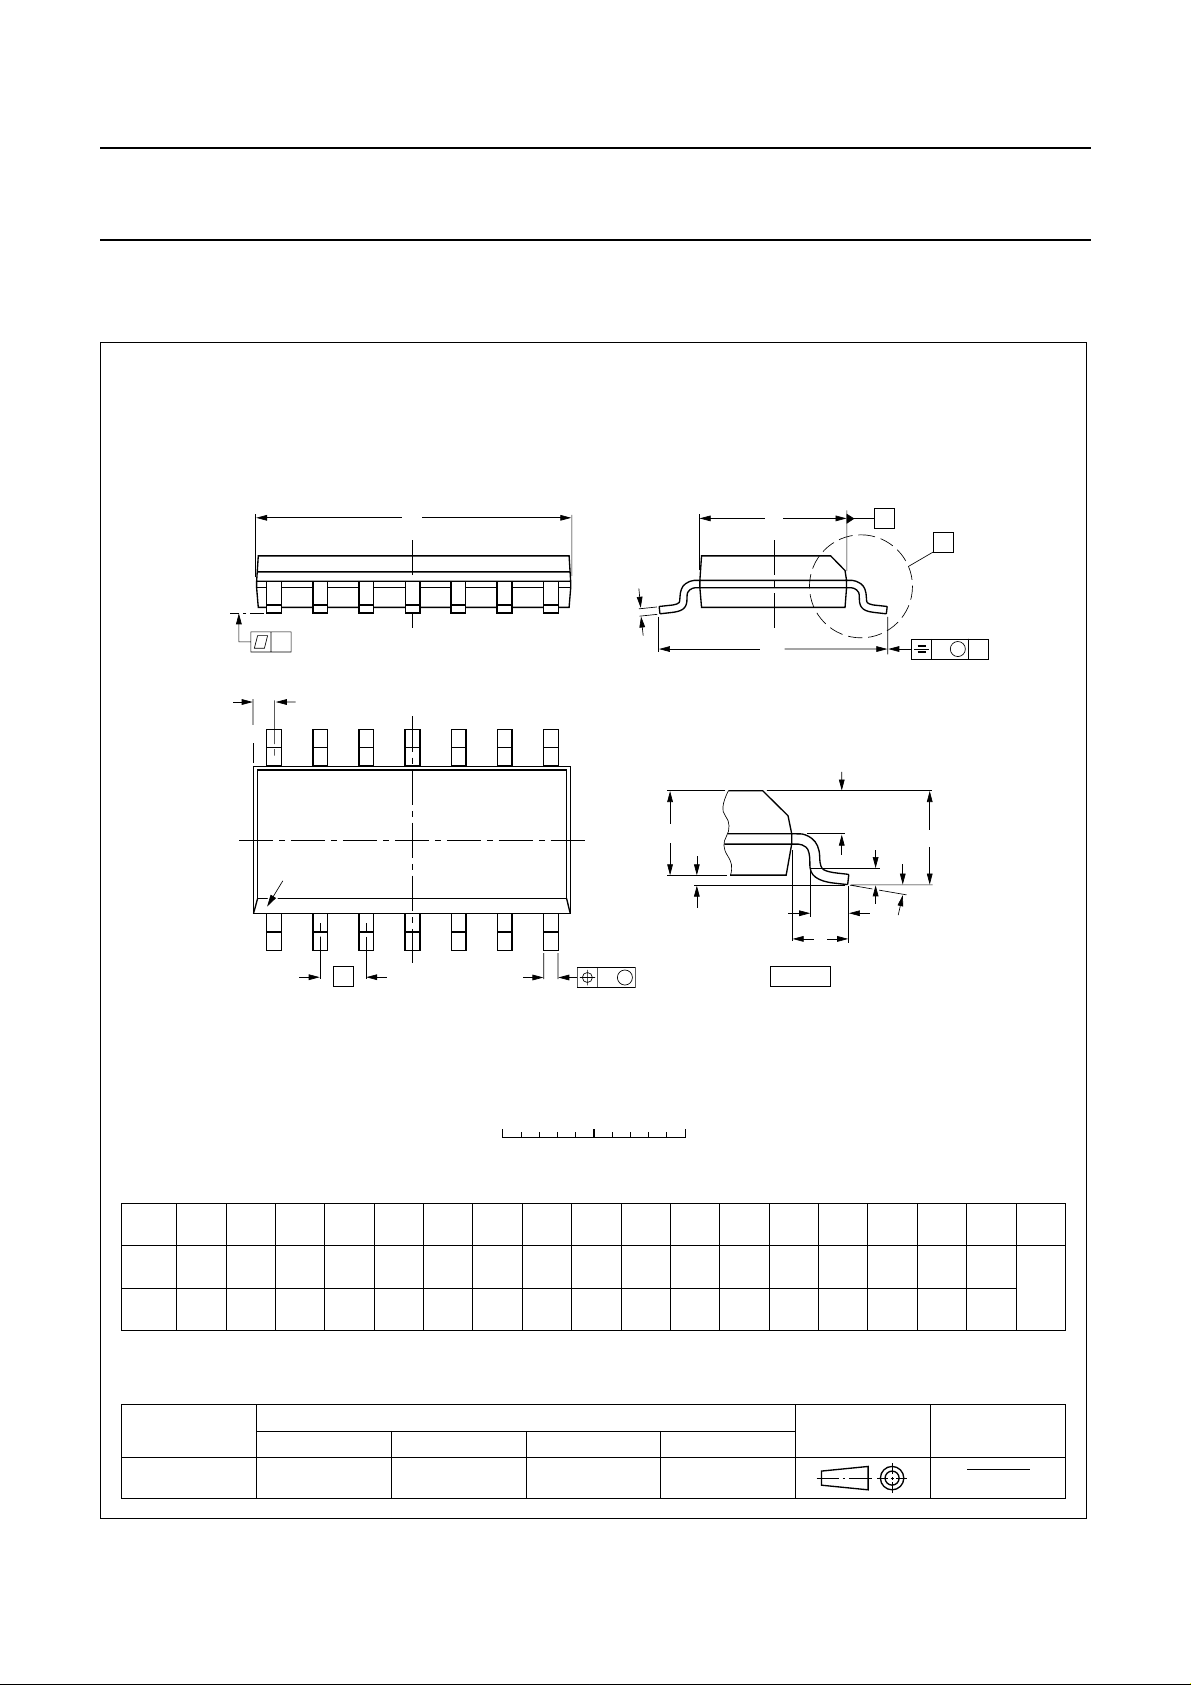
PACKAGE OUTLINE
SO14: plastic small outline package; 14 leads; body width 3.9 mm
D
c
y
Z
14
pin 1 index
1
e
8
A
2
7
w M
b
p
SOT108-1
E
H
E
A
1
L
detail X
A
X
v M
A
Q
(A )
L
p
A
3
θ
0 2.5 5 mm
scale
DIMENSIONS (inch dimensions are derived from the original mm dimensions)
mm
OUTLINE
VERSION
SOT108-1
A
max.
1.75
0.069
A
1
0.25
0.10
0.010
0.004
A2A
1.45
1.25
0.057
0.049
IEC JEDEC EIAJ
076E06S MS-012AB
0.25
0.01
b
3
p
0.49
0.25
0.36
0.19
0.019
0.0100
0.014
0.0075
UNIT
inches
Note
1. Plastic or metal protrusions of 0.15 mm maximum per side are not included.
(1)E(1)
cD
8.75
8.55
0.35
0.34
REFERENCES
4.0
3.8
0.16
0.15
1.27
0.050
1999 Feb 11 17
eHELLpQZywv θ
1.05
0.041
1.0
0.4
0.039
0.016
0.7
0.25
0.6
0.028
0.01 0.004
0.024
EUROPEAN
PROJECTION
0.25 0.1
0.01
6.2
5.8
0.244
0.228
(1)
0.7
0.3
0.028
0.012
ISSUE DATE
95-01-23
97-05-22
o
8
o
0
Page 18
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
SOLDERING
Introduction to soldering surface mount packages
This text gives a very brief insight to a complex technology.
A more in-depth account of soldering ICs can be found in
our
“Data Handbook IC26; Integrated Circuit Packages”
(document order number 9398 652 90011).
There is no soldering method that is ideal for all surface
mount IC packages. Wave soldering is not always suitable
for surface mount ICs, or for printed-circuit boards with
high population densities. In these situations reflow
soldering is often used.
Reflow soldering
Reflow soldering requires solder paste (a suspension of
fine solder particles, flux and binding agent) to be applied
to the printed-circuit board by screen printing, stencilling or
pressure-syringe dispensing before package placement.
Several methods exist for reflowing; for example,
infrared/convection heating in a conveyor type oven.
Throughput times (preheating, soldering and cooling) vary
between 100 and 200 seconds depending on heating
method.
Typical reflow peak temperatures range from
215 to 250 °C. The top-surface temperature of the
packages should preferable be kept below 230 °C.
• Use a double-wave soldering method comprising a
turbulent wave with high upward pressure followed by a
smooth laminar wave.
• For packages with leads on two sides and a pitch (e):
– larger than or equal to 1.27 mm, the footprint
longitudinal axis is preferred to be parallel to the
transport direction of the printed-circuit board;
– smaller than 1.27 mm, the footprint longitudinal axis
must be parallel to the transport direction of the
printed-circuit board.
The footprint must incorporate solder thieves at the
downstream end.
• For packages with leads on four sides, the footprint must
be placed at a 45° angle to the transport direction of the
printed-circuit board. The footprint must incorporate
solder thieves downstream and at the side corners.
During placement and before soldering, the package must
be fixed with a droplet of adhesive. The adhesive can be
applied by screen printing, pin transfer or syringe
dispensing. The package can be soldered after the
adhesive is cured.
Typical dwell time is 4 seconds at 250 °C.
A mildly-activated flux will eliminate the need for removal
of corrosive residues in most applications.
Manual soldering
Wave soldering
Conventional single wave soldering is not recommended
for surface mount devices (SMDs) or printed-circuit boards
with a high component density, as solder bridging and
non-wetting can present major problems.
To overcome these problems the double-wave soldering
method was specifically developed.
If wave soldering is used the following conditions must be
observed for optimal results:
Fix the component by first soldering two
diagonally-opposite end leads. Use a low voltage (24 V or
less) soldering iron applied to the flat part of the lead.
Contact time must be limited to 10 seconds at up to
300 °C.
When using a dedicated tool, all other leads can be
soldered in one operation within 2 to 5 seconds between
270 and 320 °C.
1999 Feb 11 18
Page 19
Philips Semiconductors Preliminary specification
Fault-tolerant CAN transceiver TJA1054
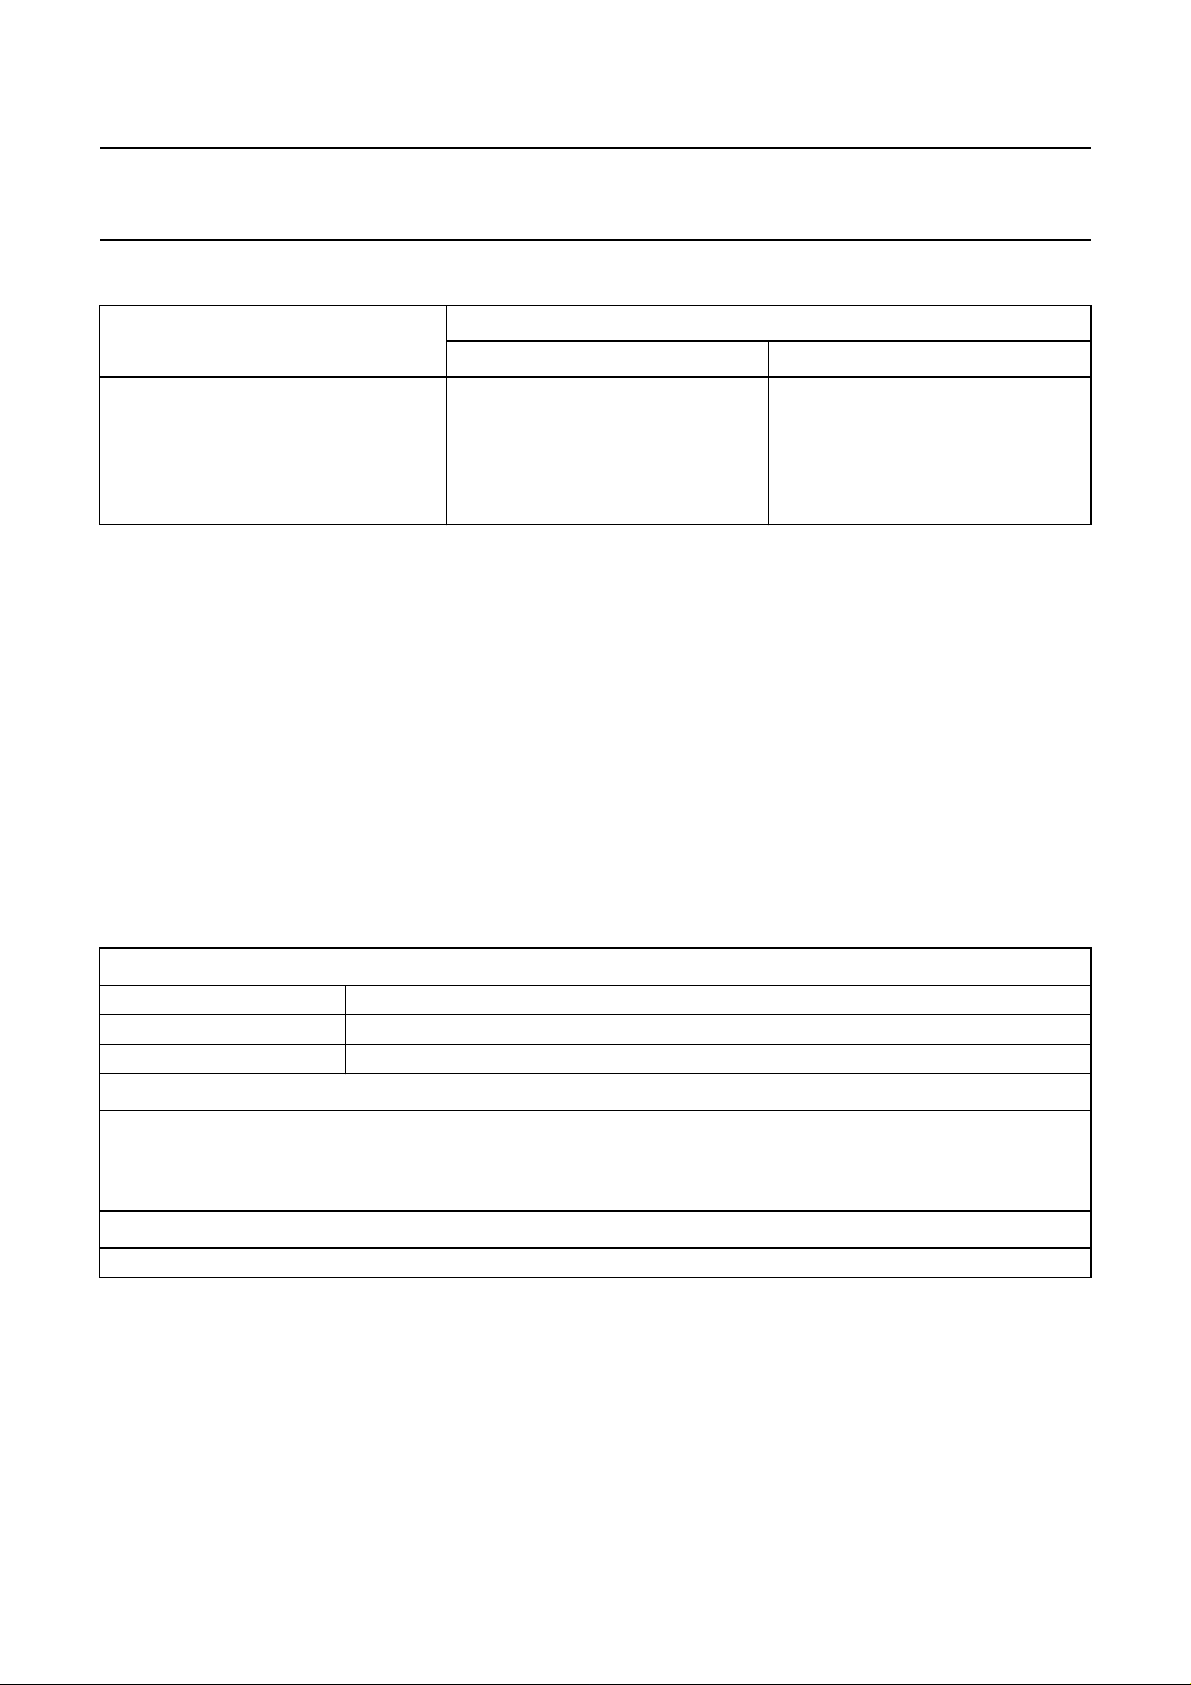
Suitability of surface mount IC packages for wave and reflow soldering methods
PACKAGE
WAVE REFLOW
(1)
BGA, SQFP not suitable suitable
SOLDERING METHOD
HLQFP, HSQFP, HSOP, HTSSOP, SMS not suitable
(3)
PLCC
, SO, SOJ suitable suitable
LQFP, QFP, TQFP not recommended
SSOP, TSSOP, VSO not recommended
(2)
(3)(4)
(5)
suitable
suitable
suitable
Notes
1. All surface mount (SMD) packages are moisture sensitive. Depending upon the moisture content, the maximum
temperature (with respect to time) and body size of the package, there is a risk that internal or external package
cracks may occur due to vaporization of the moisture in them (the so called popcorn effect). For details, refer to the
Drypack information in the
“Data Handbook IC26; Integrated Circuit Packages; Section: Packing Methods”
.
2. These packages are not suitable for wave soldering as a solder joint between the printed-circuit board and heatsink
(at bottom version) can not be achieved, and as solder may stick to the heatsink (on top version).
3. If wave soldering is considered, then the package must be placed at a 45° angle to the solder wave direction.
The package footprint must incorporate solder thieves downstream and at the side corners.
4. Wave soldering is only suitable for LQFP, TQFP and QFP packages with a pitch (e) equal to or larger than 0.8 mm;
it is definitely not suitable for packages with a pitch (e) equal to or smaller than 0.65 mm.
5. Wave soldering is only suitable for SSOP and TSSOP packages with a pitch (e) equal to or larger than 0.65 mm; it is
definitely not suitable for packages with a pitch (e) equal to or smaller than 0.5 mm.
DEFINITIONS
Data sheet status
Objective specification This data sheet contains target or goal specifications for product development.
Preliminary specification This data sheet contains preliminary data; supplementary data may be published later.
Product specification This data sheet contains final product specifications.
Limiting values
Limiting values given are in accordance with the Absolute Maximum Rating System (IEC 134). Stress above one or
more of the limiting values may cause permanent damage to the device. These are stress ratings only and operation
of the device at these or at any other conditions above those given in the Characteristics sections of the specification
is not implied. Exposure to limiting values for extended periods may affect device reliability.
Application information
Where application information is given, it is advisory and does not form part of the specification.
LIFE SUPPORT APPLICATIONS
These products are not designed for use in life support appliances, devices, or systems where malfunction of these
products can reasonably be expected to result in personal injury. Philips customers using or selling these products for
use in such applications do so at their own risk and agree to fully indemnify Philips for any damages resulting from such
improper use or sale.
1999 Feb 11 19
Page 20
Philips Semiconductors – a worldwide company
Argentina: see South America
Australia: 34 Waterloo Road, NORTH RYDE, NSW 2113,
Tel. +61 2 9805 4455, Fax. +61 2 9805 4466
Austria: Computerstr. 6, A-1101 WIEN, P.O. Box 213,
Tel. +43 1 60 101 1248, Fax. +43 1 60 101 1210
Belarus: Hotel Minsk Business Center, Bld. 3, r. 1211, Volodarski Str. 6,
220050 MINSK, Tel. +375 172 20 0733, Fax. +375 172 20 0773
Belgium: see The Netherlands
Brazil: seeSouth America
Bulgaria: Philips Bulgaria Ltd., Energoproject, 15thfloor,
51 James Bourchier Blvd., 1407 SOFIA,
Tel. +359 2 68 9211, Fax. +359 2 68 9102
Canada: PHILIPS SEMICONDUCTORS/COMPONENTS,
Tel. +1 800 234 7381, Fax. +1 800 943 0087
China/Hong Kong: 501 Hong Kong Industrial Technology Centre,
72 Tat Chee Avenue, Kowloon Tong, HONG KONG,
Tel. +852 2319 7888, Fax. +852 2319 7700
Colombia: see South America
Czech Republic: see Austria
Denmark: Sydhavnsgade 23, 1780 COPENHAGEN V,
Tel. +45 33 29 3333, Fax. +45 33 29 3905
Finland: Sinikalliontie 3, FIN-02630 ESPOO,
Tel. +358 9 615 800, Fax. +358 9 6158 0920
France: 51 Rue Carnot, BP317, 92156 SURESNES Cedex,
Tel. +33 1 4099 6161, Fax. +33 1 4099 6427
Germany: Hammerbrookstraße 69, D-20097 HAMBURG,
Tel. +49 40 2353 60, Fax. +49 40 2353 6300
Greece: No. 15, 25th March Street, GR 17778 TAVROS/ATHENS,
Tel. +30 1 489 4339/4239, Fax. +30 1 481 4240
Hungary: seeAustria
India: Philips INDIA Ltd, Band Box Building, 2nd floor,
254-D, Dr. Annie Besant Road, Worli, MUMBAI 400 025,
Tel. +91 22 493 8541, Fax. +91 22 493 0966
Indonesia: PT Philips Development Corporation, Semiconductors Division,
Gedung Philips, Jl. Buncit Raya Kav.99-100, JAKARTA 12510,
Tel. +62 21 794 0040 ext. 2501, Fax. +62 21 794 0080
Ireland: Newstead, Clonskeagh, DUBLIN 14,
Tel. +353 1 7640 000, Fax. +353 1 7640 200
Israel: RAPAC Electronics, 7 Kehilat Saloniki St, PO Box 18053,
TEL AVIV 61180, Tel. +972 3 645 0444, Fax. +972 3 649 1007
Italy: PHILIPS SEMICONDUCTORS, Piazza IV Novembre 3,
20124 MILANO, Tel. +39 2 6752 2531, Fax. +39 2 6752 2557
Japan: Philips Bldg 13-37, Kohnan 2-chome, Minato-ku,
TOKYO 108-8507, Tel. +81 3 3740 5130, Fax. +81 3 3740 5077
Korea: Philips House, 260-199 Itaewon-dong, Yongsan-ku, SEOUL,
Tel. +82 2 709 1412, Fax. +82 2 709 1415
Malaysia: No. 76 Jalan Universiti, 46200 PETALING JAYA, SELANGOR,
Tel. +60 3 750 5214, Fax. +60 3 757 4880
Mexico: 5900 Gateway East, Suite 200, EL PASO, TEXAS 79905,
Tel. +9-5 800 234 7381, Fax +9-5 800 943 0087
Middle East: see Italy
Netherlands: Postbus 90050, 5600 PB EINDHOVEN, Bldg. VB,
Tel. +31 40 27 82785, Fax. +31 40 27 88399
New Zealand: 2 Wagener Place, C.P.O. Box 1041, AUCKLAND,
Tel. +64 9 849 4160, Fax. +64 9 849 7811
Norway: Box 1, Manglerud 0612, OSLO,
Tel. +47 22 74 8000, Fax. +47 22 74 8341
Pakistan: see Singapore
Philippines: Philips Semiconductors Philippines Inc.,
106 Valero St. Salcedo Village, P.O. Box 2108 MCC, MAKATI,
Metro MANILA, Tel. +63 2 816 6380, Fax. +63 2 817 3474
Poland: Ul. Lukiska 10, PL 04-123 WARSZAWA,
Tel. +48 22 612 2831, Fax. +48 22 612 2327
Portugal: see Spain
Romania: see Italy
Russia: Philips Russia, Ul. Usatcheva 35A, 119048 MOSCOW,
Tel. +7 095 755 6918, Fax. +7 095 755 6919
Singapore: Lorong 1, Toa Payoh, SINGAPORE 319762,
Tel. +65 350 2538, Fax. +65 251 6500
Slovakia: see Austria
Slovenia: see Italy
South Africa: S.A. PHILIPS Pty Ltd., 195-215 Main Road Martindale,
2092 JOHANNESBURG, P.O. Box 7430 Johannesburg 2000,
Tel. +27 11 470 5911, Fax. +27 11 470 5494
South America: Al. Vicente Pinzon, 173, 6th floor,
04547-130 SÃO PAULO, SP, Brazil,
Tel. +55 11 821 2333, Fax. +55 11 821 2382
Spain: Balmes 22, 08007 BARCELONA,
Tel. +34 93 301 6312, Fax. +34 93 301 4107
Sweden: Kottbygatan 7, Akalla, S-16485 STOCKHOLM,
Tel. +46 8 5985 2000, Fax. +46 8 5985 2745
Switzerland: Allmendstrasse 140, CH-8027 ZÜRICH,
Tel. +41 1 488 2741 Fax. +41 1 488 3263
Taiwan: Philips Semiconductors, 6F, No. 96, Chien Kuo N. Rd., Sec. 1,
TAIPEI, Taiwan Tel. +886 2 2134 2886, Fax. +886 2 2134 2874
Thailand: PHILIPS ELECTRONICS (THAILAND) Ltd.,
209/2 Sanpavuth-Bangna Road Prakanong, BANGKOK 10260,
Tel. +66 2 745 4090, Fax. +66 2 398 0793
Turkey: Talatpasa Cad. No. 5, 80640 GÜLTEPE/ISTANBUL,
Tel. +90 212 279 2770, Fax. +90 212 282 6707
Ukraine: PHILIPS UKRAINE, 4 Patrice Lumumba str., Building B, Floor 7,
252042 KIEV, Tel. +380 44 264 2776, Fax. +380 44 268 0461
United Kingdom: Philips Semiconductors Ltd., 276 Bath Road, Hayes,
MIDDLESEX UB3 5BX, Tel. +44 181 730 5000, Fax. +44 181 754 8421
United States: 811 East Arques Avenue, SUNNYVALE, CA 94088-3409,
Tel. +1 800 234 7381, Fax. +1 800 943 0087
Uruguay: see South America
Vietnam: see Singapore
Yugoslavia: PHILIPS, Trg N. Pasica 5/v, 11000 BEOGRAD,
Tel. +381 11 62 5344, Fax.+381 11 63 5777
For all other countries apply to: Philips Semiconductors,
International Marketing & Sales Communications, Building BE-p, P.O. Box 218,
5600 MD EINDHOVEN, The Netherlands, Fax. +31 40 27 24825
© Philips Electronics N.V. 1999 SCA62
All rights are reserved. Reproduction in whole or in part is prohibited without the prior written consent of the copyright owner.
The information presented in this document does not form part of any quotation or contract, is believed to be accurate and reliable and may be changed
without notice. No liability will be accepted by the publisher for any consequence of its use. Publication thereof does not convey nor imply any license
under patent- or other industrial or intellectual property rights.
Internet: http://www.semiconductors.philips.com
Printed in The Netherlands 285002/00/01/pp20 Date of release: 1999 Feb 11 Document order number: 9397 750 03636
 Loading...