

Page 1

INTEGRATED CIRCUITS
DATA SH EET
TJA1050
High speed CAN transceiver
Preliminary specification
File under Integrated Circuits, IC18
1999 Sep 27
Page 2

Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
FEATURES
• Fully compatible with the
“ISO 11898”
standard
• High speed (up to 1 Mbaud)
• Transmit Data (TXD) dominant time-out function
• Bus lines protected against transients in an automotive
environment
• Silent mode in which the transmitter is disabled
• Differential receiver with wide common-mode range for
high ElectroMagnetic Immunity (EMI)
• Input levels compatible with 3.3 V devices
GENERAL DESCRIPTION
The TJA1050 is the interface between the CAN protocol
controller and the physical bus. The device provides
differential transmit capability to the bus and differential
receive capability to the CAN controller.
The TJA1050 is the successor to the PCA82C250 high
speed CAN transceiver. The most important
improvements are:
• Much lower ElectroMagnetic Emission (EME) due to
optimal matchingofthe CANH and CANL output signals
• Improved behaviour in case of an unpowered node.
• Thermally protected
• Short-circuit proof to battery and ground
• An unpowered node does not disturb the bus lines
• At least 110 nodes can be connected.
QUICK REFERENCE DATA
SYMBOL PARAMETER CONDITIONS MIN. MAX. UNIT
V
CC
V
CANH
V
CANL
V
i(dif)(bus)
t
PD(TXD-RXD)
supply voltage 4.75 5.25 V
DC voltage at CANH 0 < VCC< 5.25 V; no time limit −27 +40 V
DC voltage at CANL
differential bus input voltage dominant 1.5 3 V
propagation delay TXD to RXD;
VS=0V − 250 ns
see Fig.4
T
amb
operating ambient temperature −40 +125 °C
ORDERING INFORMATION
TYPE
NUMBER
NAME DESCRIPTION VERSION
PACKAGE
TJA1050T SO8 plastic small outline package; 8 leads; body width 3.9 mm SOT96-1
TJA1050U − bare die −
1999 Sep 27 2
Page 3

Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
BLOCK DIAGRAM
PINNING
handbook, full pagewidth
TXD
RXD
V
V
CC
0.5V
CC
GND
3
GND
2
25
kΩ
25
kΩ
MGS374
7
CANH
CANL
6
8
S
60 µA
V
CC
GND
200
µA
1
V
CC
4
GND
5
ref
TXD
DOMINANT
TIME-OUT
TIMER
REFERENCE
VOLTAGE
RECEIVER
TJA1050
TEMPERATURE
PROTECTION
DRIVER
Fig.1 Block diagram.
SYMBOL PIN DESCRIPTION
TXD 1 transmit data input; reads in data
from the CAN controller to the bus
line drivers
GND 2 ground
V
CC
3 supply voltage
RXD 4 receive data output; reads out
data from the bus lines to the
CAN controller
V
ref
5 reference voltage output
CANL 6 LOW-level CAN bus line
CANH 7 HIGH-level CAN bus line
S 8 select input for
high speed mode/silent mode
handbook, halfpage
TXD
1
V
CC
RXD
2
TJA1050T
3
4
7
6
5
MGS375
Fig.2 Pin configuration.
8
S
CANHGND
CANL
V
ref
1999 Sep 27 3
Page 4

Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
FUNCTIONAL DESCRIPTION
The TJA1050 is the interface between the CAN protocol
controller and the physical bus. It is primarily intended for
high speed automotive applications using baud rates from
40 kbaud up to 1 Mbaud. It provides differential transmit
capability to the bus and differential receiver capability to
the CAN protocol controller. It is fully compatible to the
“ISO 11898”
standard.
A current-limiting circuit protects the transmitter output
stage from damage caused by accidental short-circuit to
either positive or negative battery voltage, although power
dissipation increases during this fault condition.
Athermalprotection circuit protects theICfromdamage by
switching off the transmitter if the junction temperature
exceeds a value of approximately 165 °C. Because the
transmitter dissipates most of the power, the power
dissipation and temperature of the IC is reduced. All other
IC functions continue to operate. The transmitter off-state
resets when TXD goes HIGH. The thermal protection
circuit is particularly needed whena bus line short-circuits.
The CANH and CANL lines are protected fromautomotive
electrical transients (according to
“ISO 7637”
; see Fig.6)
and are also protected from Electro-Static-Discharge
(ESD) of up to 4 kV from the human body.
Control line S (pin 8) allows two operating modes to be
selected; high speed mode or silent mode.
High speed mode is the normal operating mode and is
selected by connecting pin S to ground. It is the default
mode if pin S is unconnected.
In the silent mode, the transmitter is disabled. All other IC
functions continue to operate. The silent mode is selected
by connecting pin S to VCC.
A ‘TXD Dominant Time-out’ timer circuit prevents the bus
linesbeing driven toa permanent dominantstate(blocking
all network communication) if TXD is forced permanently
LOW by a hardware and/or software application failure.
The timer is triggered by a negative edge on TXD. If the
duration of the LOW-level on TXD exceeds the internal
timer value, the transmitter isdisabled, drivingthe businto
a recessive state. The timer is reset by a positive edge on
TXD.
Table 1 Function table of the CAN transceiver
(X = don’t care)
V
CC
TXD S CANH CANL BUS STATE RXD
4.75 to 5.25 V 0 0 (or floating) HIGH LOW dominant 0
4.75 to 5.25 V X 1 0.5 × V
4.75 to 5.25 V 1 (or floating) X 0.5 × V
CC
CC
<2 V (not powered) X X 0 V <CANH< V
2V<V
< 4.75 V >2 V X 0 V <CANH< V
CC
CC
CC
0.5 × V
CC
0.5 × V
CC
0 V <CANL< V
0 V <CANL< V
recessive 1
recessive 1
recessive X
CC
recessive X
CC
1999 Sep 27 4
Page 5

Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
LIMITING VALUES
In accordance with the Absolute Maximum Rating System (IEC 134). All voltages are referenced to GND (pin 2).
Positive currents flow into the IC.
SYMBOL PARAMETER CONDITIONS MIN. MAX. UNIT
V
CC
V
CANL
V
TXD
V
and V
ref
V
trt(CANH)
V
trt(CANL)
V
esd
T
stg
T
amb
T
j
, V
, V
CANH
RXD
,
supply voltage −0.3 +5.25 V
DC voltage at CANL and CANH 0 < VCC< 5.25 V;
−27 +40 V
no time limit
,
DC voltage at TXD, RXD, V
S
and S −0.3 VCC+ 0.3 V
ref
transient voltage at CANH and CANL time limit is 1 µs −55 +55 V
note 1 −200 +200 V
electrostatic discharge at CANH; CANL note 3 −4+4kV
electrostatic discharge at TXD; V
RXD; V
and S
ref
CC
;
note 3 −2+2kV
electrostatic discharge at all pins note 4 −200 +200 V
storage temperature −55 +150 °C
operating ambient temperature −40 +125 °C
junction temperature note 2 −40 +150 °C
Notes
1. The waveforms of the applied transients shall be in accordance with
“ISO 7637 part 1”
, test pulses 1, 2, 3a and 3b,
(see Fig.6).
2. In accordance with
“IEC 747-1”
. An alternative definition of Tjis: Tj=T
amb
+P×R
th(j-a)
, where R
is a fixed value
th(j-a)
to be used for the calculation of Tj. The rating for Tj limits the allowable combinations of power dissipation (P) and
ambient temperature (T
amb
).
3. Human body model; C = 100 pF R = 1.5 kΩ.
4. Machine model; C = 200 pF R = 25 Ω.
THERMAL CHARACTERISTICS
According to IEC 747-1.
SYMBOL PARAMETER CONDITIONS VALUE UNIT
R
th(j-a)
thermal resistance from junction to
in free air 160 K/W
ambient; TJA1050T(SO8)
QUALITY SPECIFICATION
Quality specification
“SNW-FQ-611 part D”
is applicable.
1999 Sep 27 5
Page 6
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
CHARACTERISTICS
VCC= 4.75 to 5.25 V; T
(pin 2); positive currents flow into the IC; all parameters are guaranteed over the ambient temperature range by design,
but only 100% tested at T
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
= −40 to +125 °C; RL=60Ωunless specified otherwise; all voltages are referenced to GND
amb
=25°C unless specified otherwise.
amb
Supply (V
I
CC
)
CC
supply current dominant; V
Transmitter data input (TXD)
V
V
I
IH
I
IL
C
IH
IL
i(TXD)
HIGH-level input voltage output recessive 2.0 − VCC+ 0.3 V
LOW-level input voltage output dominant −0.3 − +0.8 V
HIGH-level input current V
LOW-level input current V
TXD input capacitance not tested −−tbf pF
Mode select input (S)
V
IH
V
IL
I
IH
I
IL
HIGH-level input voltage silent mode 2.0 − VCC+ 0.3 V
LOW-level input voltage high speed mode −0.3 − +0.8 V
HIGH-level input current VS=V
LOW-level input current VS=0V −30 0 +30 µA
Receiver data output (RXD)
I
OH
I
OL
V
ref
V
ref
HIGH-level output current V
LOW-level output current V
reference output voltage −50 µA<I
Bus lines (CANH; CANL)
V
CANH(reces)
V
CANL(reces)
I
o(CANH)(reces)
I
o(CANL)(reces)
V
o(CANH)
;
recessive bus voltage V
;
recessive output current −27V<V
CANH dominant output
voltage
V
o(CANL)
CANL dominant output
voltage
V
i(dif)(bus)
I
o(sc)(CANH)
differential bus input voltage
(V
CANH
− V
CANL
CANH short-circuit output
current
I
o(sc)(CANL)
CANL short-circuit output
current
=0V tbf − 75 mA
TXD
recessive; V
TXD=VCC
TXD
RXD
RXD
TXD=VCC
V
CANL
TXD=VCC
=0V −100 −200 −300 µA
CC
= 0.7 V
CC
= 0.45 V 2 8.5 20 mA
<50µA 0.45V
Vref
; no load 2.0 − 3.0 V
,
CANH
<32V;
tbf − 13 mA
−30 0 +30 µA
30 60 100 µA
tbf tbf tbf mA
CC
0.5V
CC
0.55V
CC
V
−2.5 − +2.5 mA
0V<VCC< 5.25 V
V
= 0 V 2.8 − 4.5 V
TXD
0.5 − 2.0 V
V
=0V;
TXD
)
42.5 < RL<60Ω
1.5 − 3.0 V
(dominant)
V
TXD=VCC
; no load
−500 − +50 mV
(recessive)
V
V
V
V
CANH
TXD
CANL
TXD
=0V;
=0V
=36V;
=0V
−35 −−95 mA
35 − 150 mA
1999 Sep 27 6
Page 7
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
V
dif(th)
V
i(dif)(hys)
R
i(cm)(CANH)
R
i(cm)(CANL)
R
i(cm)(m)
R
i(dif)
i(CANH)
i(CANL)
i(dif)
;
;
C
C
C
I
LI(CANH)
I
LI(CANL)
Thermal shutdown
T
j(sd)
Timing characteristics (see Figs 3 and 4)
t
d(TXD-BUSon)
t
d(TXD-BUSoff)
t
d(BUSon-RXD)
t
d(BUSoff-RXD)
differentialreceiverthreshold
voltage
differential receiver input
−12V<V
V
< 12 V; see Fig.5
CANL
CANH,
0.5 0.7 0.9 V
see Fig.5 100 − 200 mV
voltage hysteresis
;
CANH; CANL common
10 25 50 kΩ
mode input resistance
matching between CANH
V
CANH=VCANL
−3 − +3 %
and CANL common mode
input resistance
differential input resistance 20 50 100 kΩ
CANH; CANL input
V
TXD=VCC
; not tested −−20 pF
capacitance
differential input capacitance −−10 pF
CANH; CANL input leakage
current
shutdown junction
VCC=0V;
V
CANH=VCANL
−−500 µA
=5V
155 165 180 °C
temperature
delay TXD to bus active VS= 0 V tbf tbf 150 ns
delay TXD to bus inactive
delay bus active to RXD tbf tbf 100 ns
delay bus inactive to RXD
1999 Sep 27 7
Page 8
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
TEST AND APPLICATION INFORMATION
+
5 V
handbook, halfpage
TXD
V
RXD
15 pF
µF
100
47
nF
V
CC
ref
1
5
4
3
TJA1050
GND S
CANH
7
R
L
60 Ω
CANL
6
82
C
L
100 pF
handbook, full pagewidth
TXD
CANH
CANL
V
i(dif)(bus)
RXD
t
d(TXD-BUSon)
t
d(BUSon − RXD)
MGS376
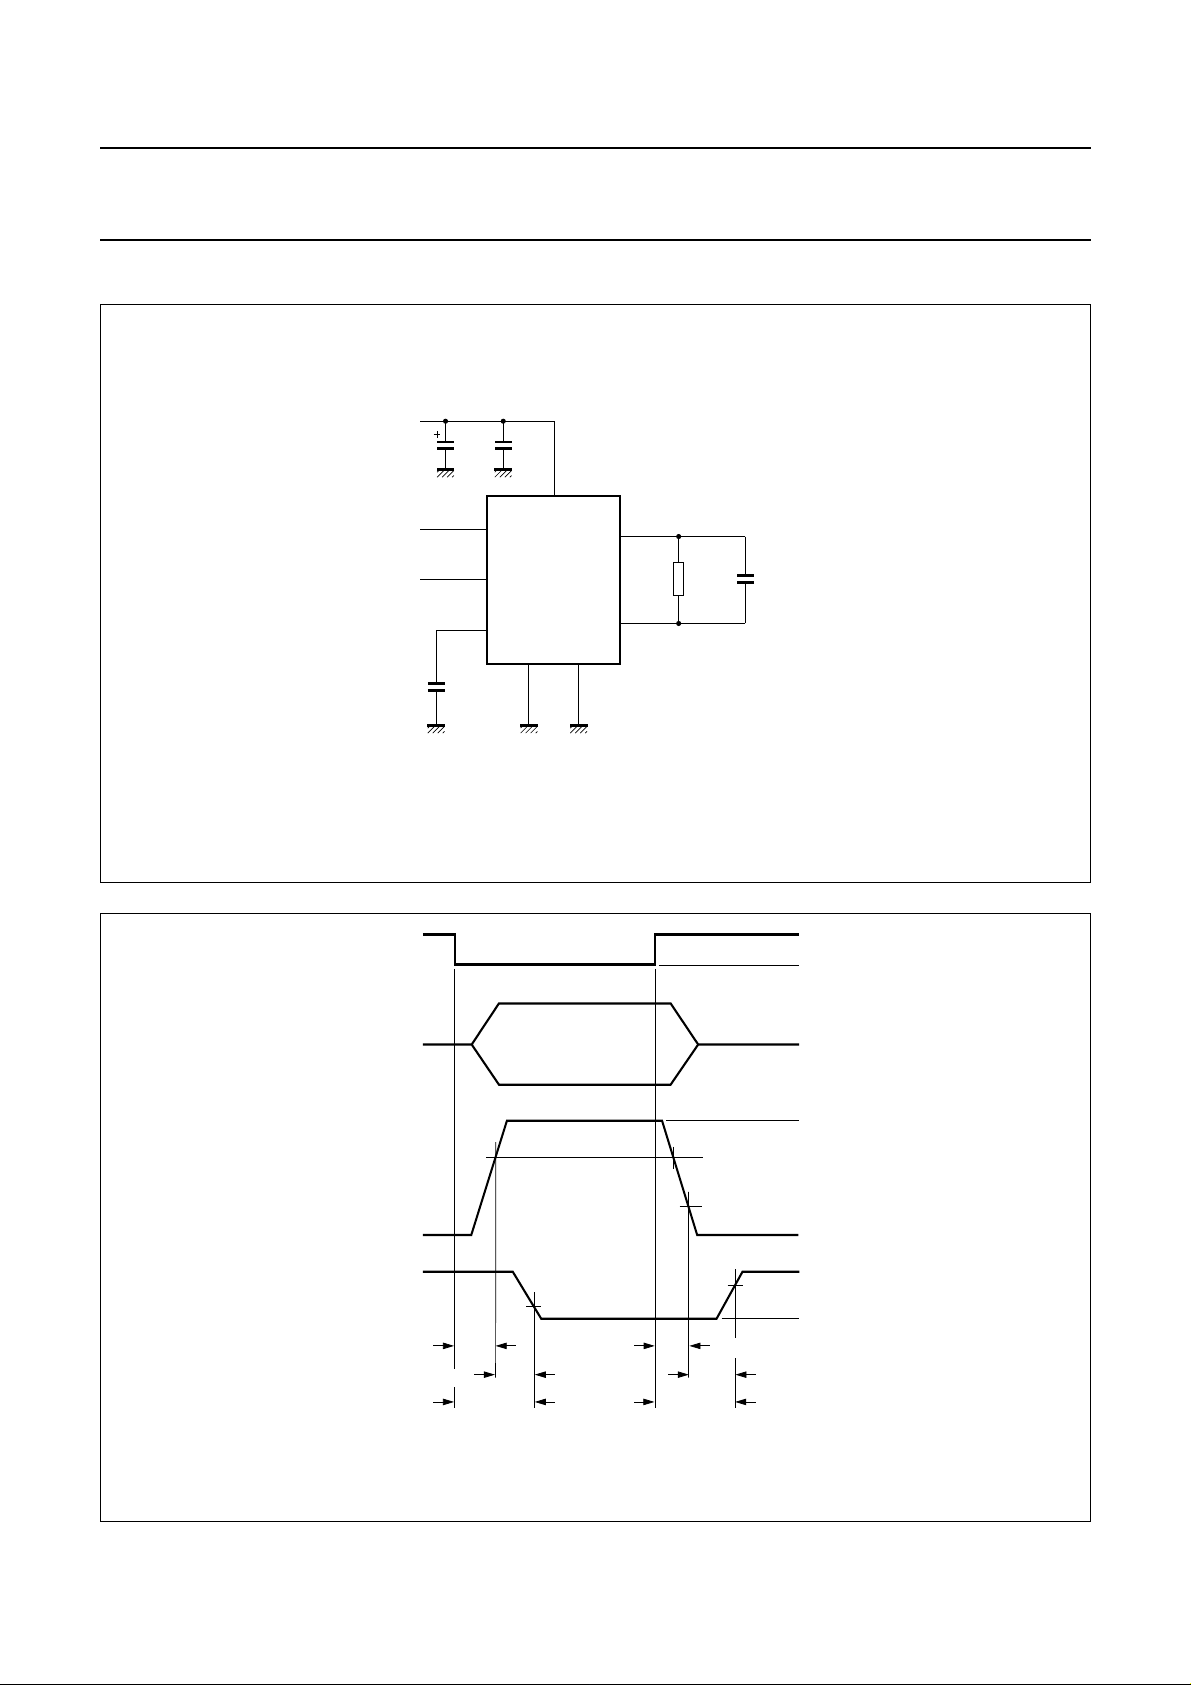
Fig.3 Test circuit for timing characteristics.
0.9 V
(1)
0.5 V
0.3V
CC
0.7V
t
d(TXD-BUSoff)
HIGH
LOW
dominant
(BUS on)
recessive
(BUS off)
HIGH
CC
LOW
t
d(BUSoff − RXD)
(1) V
i(dif)(bus)
= V
CANH
− V
CANL
t
PD(TXD − RXD
)
Fig.4 Timing diagram for AC characteristics.
1999 Sep 27 8
t
PD(TXD − RXD
)
MGS377
Page 9
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
handbook, full pagewidth
handbook, full pagewidth
V
RXD
+
5 V
hysteresis
0.5 0.9
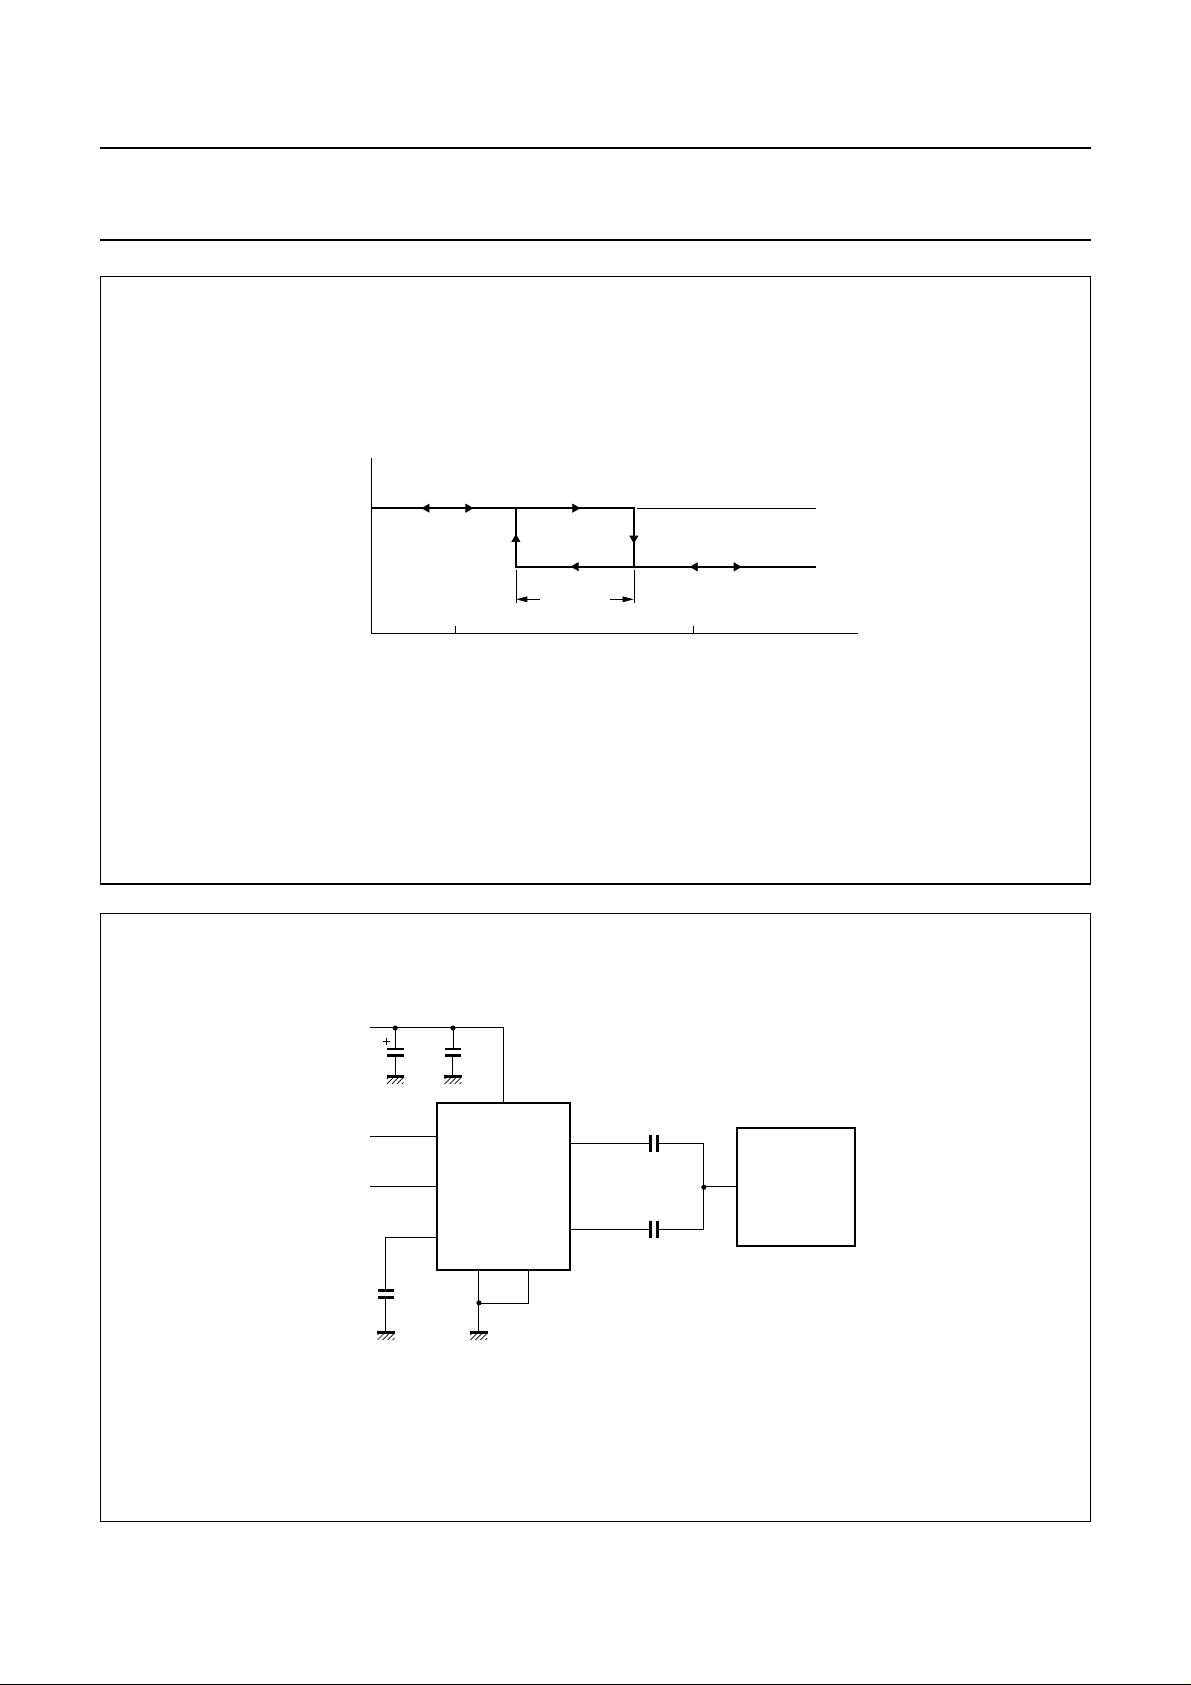
Fig.5 Hysteresis of the receiver.
100
47
nF
µF
V
CC
1
5
TJA1050
4
3
82
GND S
7
6
CANH
CANL
TXD
V
ref
RXD
15 pF
1 nF
1 nF
MGS378
HIGH
LOW
V
i(dif)(bus)
TRANSIENT
GENERATOR
MGS379
The waveforms of the applied transients shall be in accordance with
“ISO 7637 part 1”
Fig.6 Test circuit for automotive transients.
1999 Sep 27 9
, test pulses 1, 2, 3a and 3b.
Page 10
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
+
TX0
RX0
5 V
47
µF
TXD
V
ref
RXD
100
nF
1
5
4
V
CC
3
TJA1050
GND S
120 Ω
CANH
7
CAN
CANL
6
82
MGS380
BUS LINE
120 Ω
handbook, full pagewidth
SJA1000
CAN
CONTROLLER
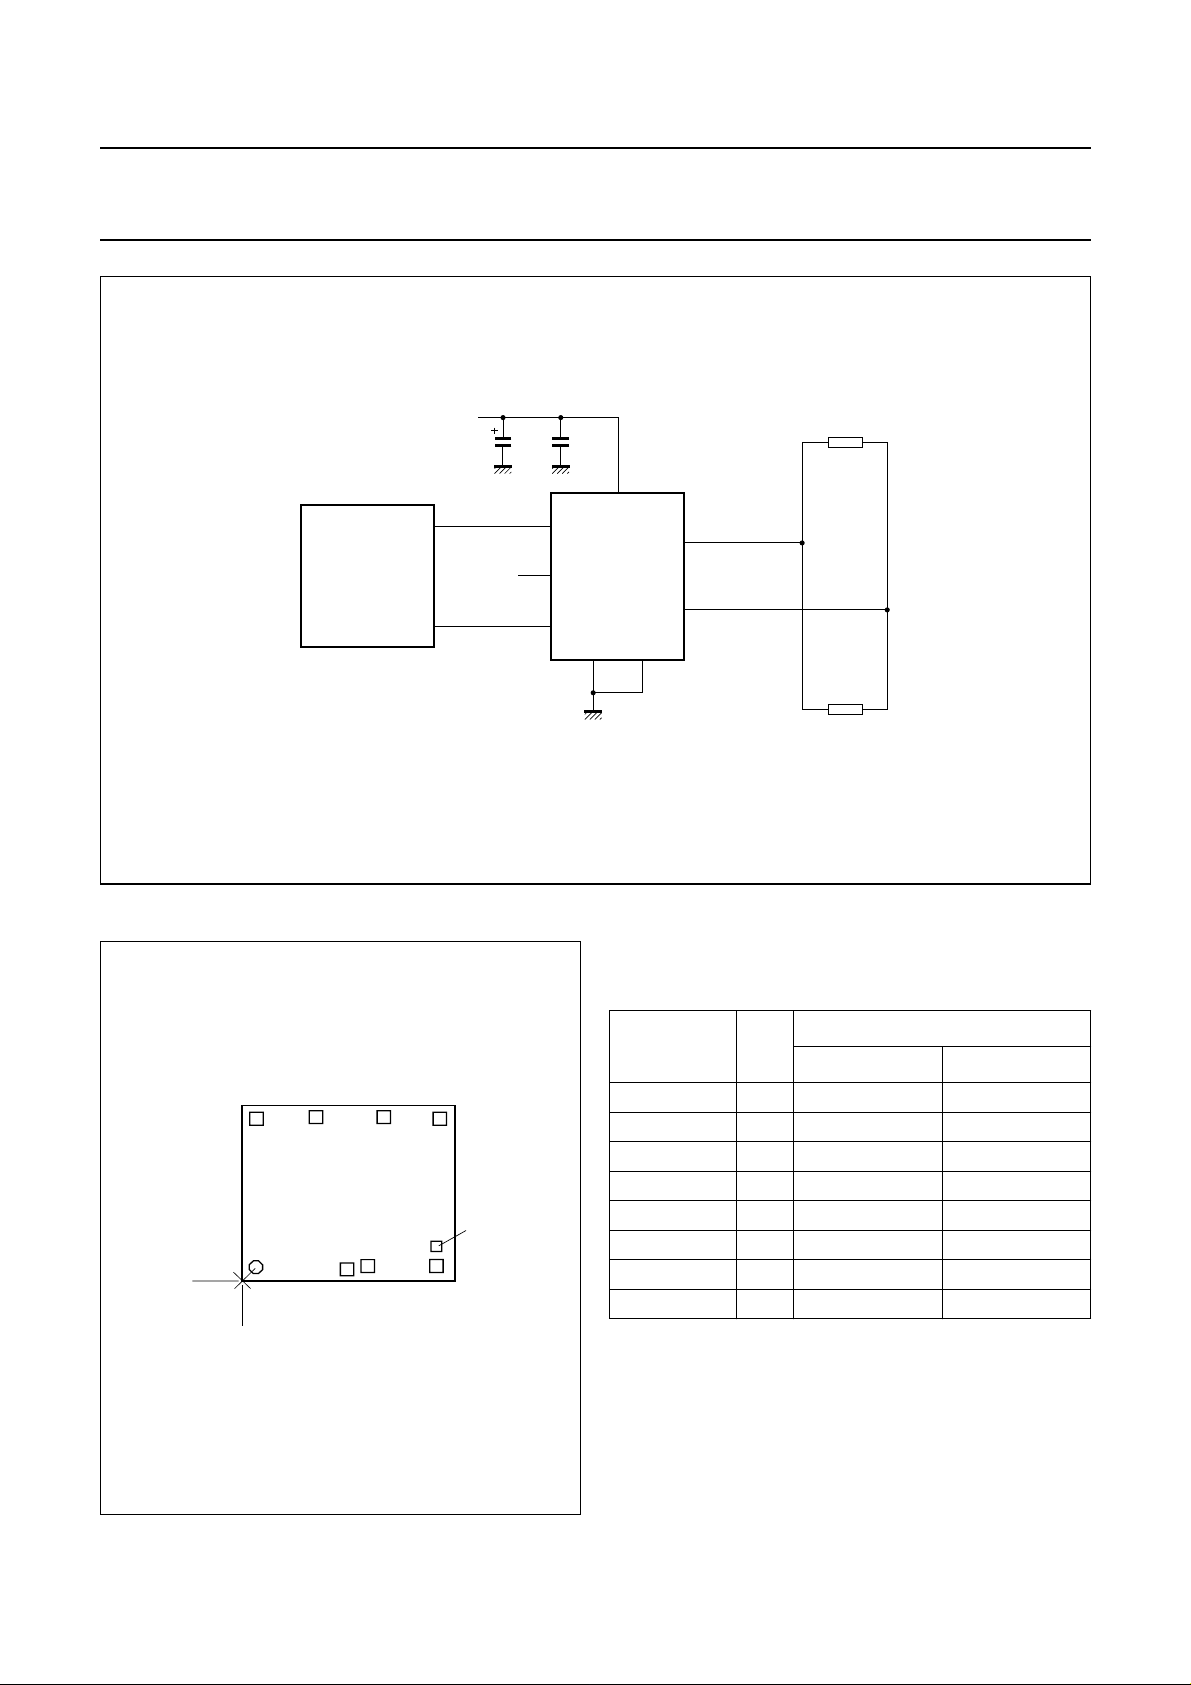
Fig.7 Application information.
BONDING PAD LOCATIONS FOR TJA1050U Table 2 Bonding pad locations
All x/y coordinates represent the position of the centre of
each pad (in µm) with respect to x/y = 0 of the die (see
Fig.8).
SYMBOL PAD
8
andbook, halfpage
765
TXD 1 103 103
GND 2 740.5 85
TJA1050U
test pad
V
CC
RXD 4 1371.5 111
V
ref
3 886.5 111
5 1394 1094
CANL 6 1006 1111
x
0
0
1
y
23 4
MGS381
CANH 7 542.5 1111
S 8 103 1097
COORDINATES
xy
Fig.8 Bonding pad locations.
1999 Sep 27 10
Page 11
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
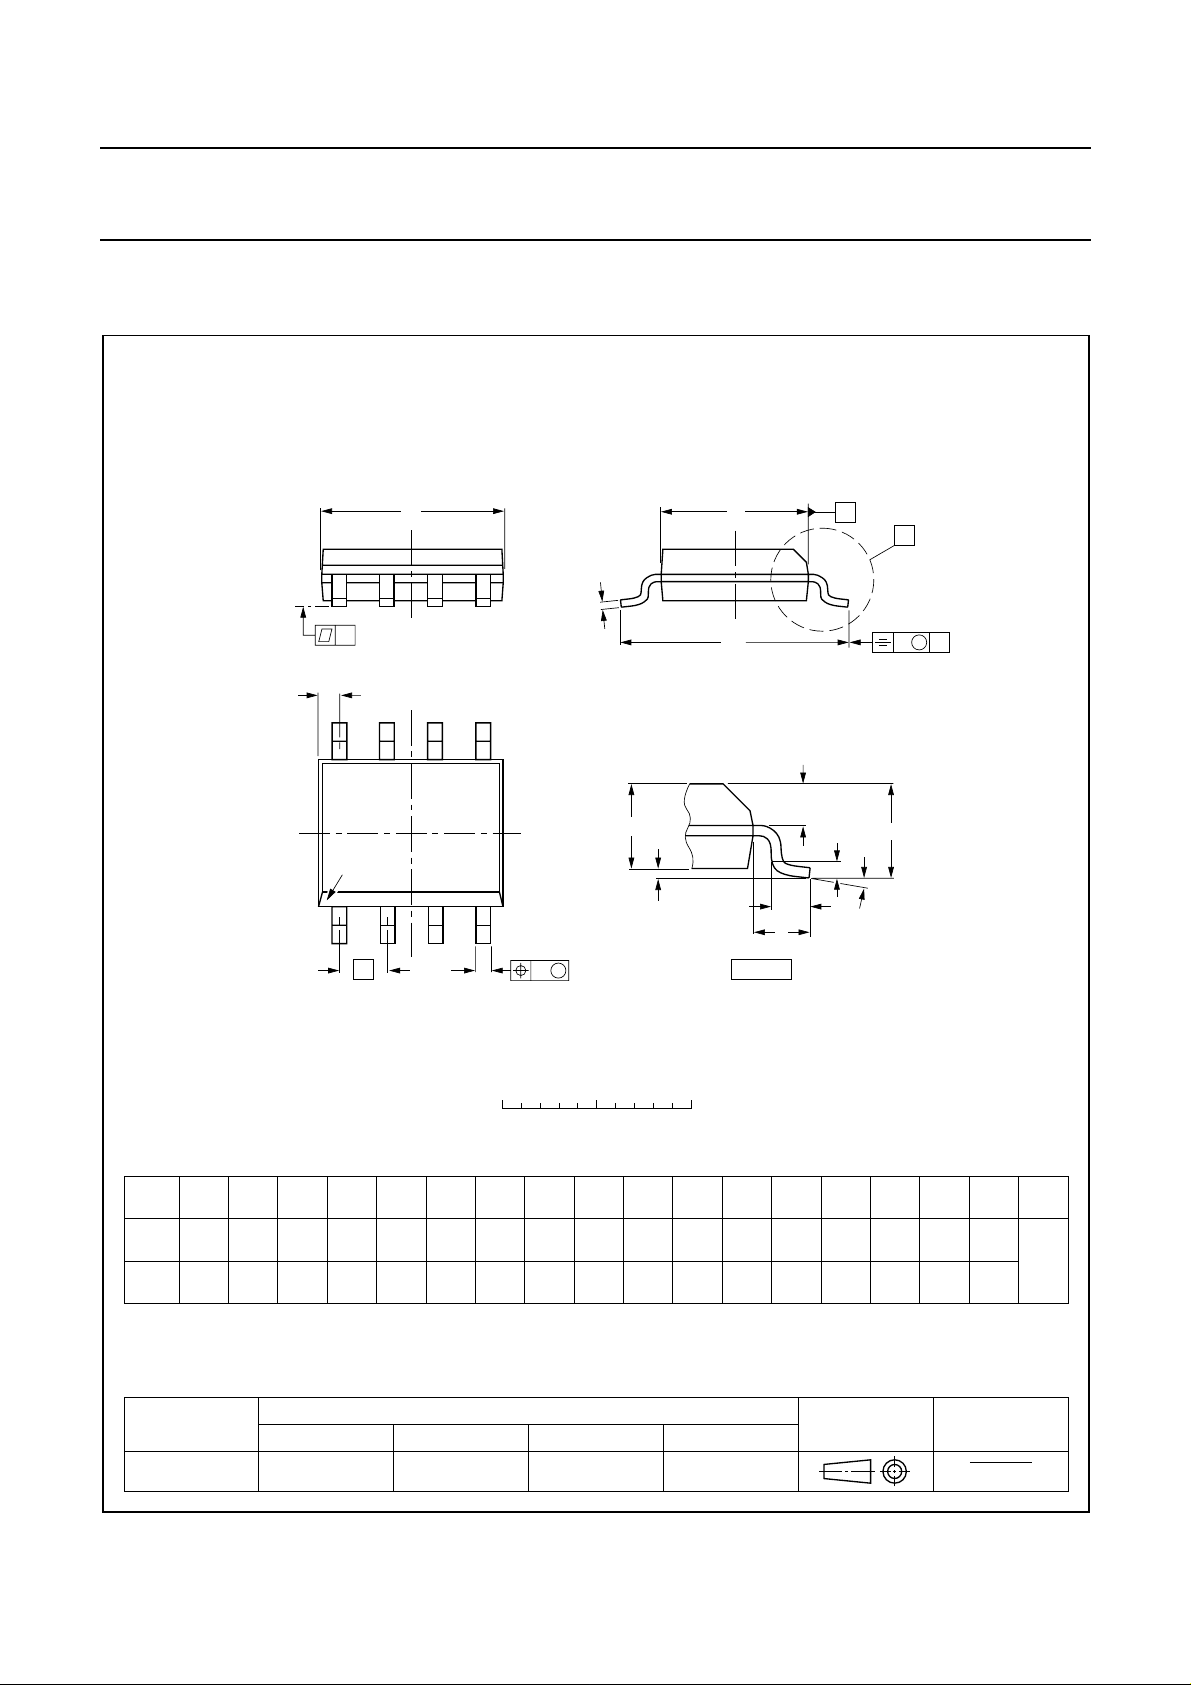
PACKAGE OUTLINE
SO8: plastic small outline package; 8 leads; body width 3.9 mm
SOT96-1
y
Z
8
pin 1 index
1
D
c
5
A
2
A
1
4
e
w M
b
p
E
H
E
detail X
A
X
v M
A
Q
(A )
L
p
L
A
3
θ
0 2.5 5 mm
scale
DIMENSIONS (inch dimensions are derived from the original mm dimensions)
mm
OUTLINE
VERSION
SOT96-1
A
max.
1.75
0.069
A1A2A
0.25
1.45
0.10
1.25
0.010
0.057
0.004
0.049
IEC JEDEC EIAJ
076E03S MS-012AA
0.25
0.01
b
3
p
0.49
0.25
0.36
0.19
0.019
0.0100
0.014
0.0075
UNIT
inches
Notes
1. Plastic or metal protrusions of 0.15 mm maximum per side are not included.
2. Plastic or metal protrusions of 0.25 mm maximum per side are not included.
(1)E(2)
cD
5.0
4.8
0.20
0.19
REFERENCES
4.0
3.8
0.16
0.15
1.27
0.050
1999 Sep 27 11
eHELLpQZywv θ
1.05
1.0
0.4
0.039
0.016
0.7
0.6
0.028
0.024
0.25 0.10.25
0.010.010.041 0.004
EUROPEAN
PROJECTION
6.2
5.8
0.244
0.228
(1)
0.7
0.3
0.028
0.012
ISSUE DATE
95-02-04
97-05-22
o
8
o
0
Page 12
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
SOLDERING
Introduction to soldering surface mount packages
Thistext gives averybriefinsight to acomplextechnology.
A more in-depth account of soldering ICs can be found in
our
“Data Handbook IC26; Integrated Circuit Packages”
(document order number 9398 652 90011).
There is no soldering method that is ideal for all surface
mount IC packages.Wave soldering is not alwayssuitable
for surface mount ICs, or for printed-circuit boards with
high population densities. In these situations reflow
soldering is often used.
Reflow soldering
Reflow soldering requires solder paste (a suspension of
fine solder particles, flux and binding agent) to be applied
tothe printed-circuit boardby screen printing,stencillingor
pressure-syringe dispensing before package placement.
Several methods exist for reflowing; for example,
infrared/convection heating in a conveyor type oven.
Throughput times (preheating, soldering andcooling) vary
between 100 and 200 seconds depending on heating
method.
Typical reflow peak temperatures range from
215 to 250 °C. The top-surface temperature of the
packages should preferable be kept below 230 °C.
Wave soldering
Conventional single wave soldering is not recommended
forsurface mount devices (SMDs)orprinted-circuit boards
with a high component density, as solder bridging and
non-wetting can present major problems.
To overcome these problems the double-wave soldering
method was specifically developed.
If wave soldering is used the following conditions must be
observed for optimal results:
• Use a double-wave soldering method comprising a
turbulent wave with high upward pressure followed by a
smooth laminar wave.
• For packages with leads on two sides and a pitch (e):
– larger than or equal to 1.27 mm, the footprint
longitudinal axis is preferred to be parallel to the
transport direction of the printed-circuit board;
– smaller than 1.27 mm, the footprint longitudinal axis
must be parallel to the transport direction of the
printed-circuit board.
The footprint must incorporate solder thieves at the
downstream end.
• Forpackages with leads onfoursides, the footprint must
be placedat a 45° angle to the transport direction of the
printed-circuit board. The footprint must incorporate
solder thieves downstream and at the side corners.
During placement and before soldering,the packagemust
be fixed with a droplet of adhesive. The adhesive can be
applied by screen printing, pin transfer or syringe
dispensing. The package can be soldered after the
adhesive is cured.
Typical dwell time is 4 seconds at 250 °C.
A mildly-activated flux will eliminate the need for removal
of corrosive residues in most applications.
Manual soldering
Fix the component by first soldering two
diagonally-opposite end leads. Use a low voltage (24 V or
less) soldering iron applied to the flat part of the lead.
Contact time must be limited to 10 seconds at up to
300 °C.
When using a dedicated tool, all other leads can be
soldered in one operation within 2 to 5 seconds between
270 and 320 °C.
1999 Sep 27 12
Page 13
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
Suitability of surface mount IC packages for wave and reflow soldering methods
PACKAGE
WAVE REFLOW
(1)
BGA, SQFP not suitable suitable
SOLDERING METHOD
HLQFP, HSQFP, HSOP, HTSSOP, SMS not suitable
(3)
PLCC
, SO, SOJ suitable suitable
LQFP, QFP, TQFP not recommended
SSOP, TSSOP, VSO not recommended
(2)
(3)(4)
(5)
suitable
suitable
suitable
Notes
1. All surface mount (SMD) packages are moisture sensitive. Depending upon the moisture content, the maximum
temperature (with respect to time) and body size of the package, there is a risk that internal or external package
cracks may occur due to vaporization of the moisture in them (the so called popcorn effect). For details, refer to the
Drypack information in the
“Data Handbook IC26; Integrated Circuit Packages; Section: Packing Methods”
.
2. These packages are not suitable for wave soldering as a solder joint between the printed-circuit board and heatsink
(at bottom version) can not be achieved, and as solder may stick to the heatsink (on top version).
3. If wave soldering is considered, then the package must be placed at a 45° angle to the solder wave direction.
The package footprint must incorporate solder thieves downstream and at the side corners.
4. Wave soldering is only suitable for LQFP, TQFP and QFP packages with a pitch (e) equal to or larger than 0.8 mm;
it is definitely not suitable for packages with a pitch (e) equal to or smaller than 0.65 mm.
5. Wave soldering is only suitable for SSOP andTSSOP packages with a pitch (e) equalto or larger than 0.65 mm; it is
definitely not suitable for packages with a pitch (e) equal to or smaller than 0.5 mm.
1999 Sep 27 13
Page 14
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
DEFINITIONS
Data sheet status
Objective specification This data sheet contains target or goal specifications for product development.
Preliminary specification This data sheet contains preliminary data; supplementary data may be published later.
Product specification This data sheet contains final product specifications.
Limiting values
Limiting values given are in accordance with the Absolute Maximum Rating System (IEC 134). Stress above one or
more of the limiting values may cause permanent damage to the device. These are stress ratings only and operation
of the device at these or at any other conditions above those given in the Characteristics sections of the specification
is not implied. Exposure to limiting values for extended periods may affect device reliability.
Application information
Where application information is given, it is advisory and does not form part of the specification.
LIFE SUPPORT APPLICATIONS
These products are not designed for use in life support appliances, devices, or systems where malfunction of these
products can reasonably be expected to result in personal injury. Philips customers using or selling these products for
use in such applications do so at their own risk and agree to fully indemnify Philips for any damages resulting from such
improper use or sale.
BARE DIE DISCLAIMER
All die are tested and are guaranteed to comply with all data sheet limits up to the point of wafer sawing for a period of
ninety (90) days from the date of Philips' delivery. If there are data sheet limits not guaranteed, these will be separately
indicated in the data sheet. There is no post waffle pack testing performed on individual die. Although the most modern
processes are utilized for wafer sawing and die pick and place into waffle pack carriers, Philips Semiconductors has no
control of third party procedures in the handling, packing or assembly of the die. Accordingly, Philips Semiconductors
assumes no liability for device functionality or performance of the die or systems after handling, packing or assembly of
the die. It is the responsibility of the customer to test and qualify their application in which the die is used.
1999 Sep 27 14
Page 15
Philips Semiconductors Preliminary specification
High speed CAN transceiver TJA1050
NOTES
1999 Sep 27 15
Page 16
Philips Semiconductors – a w orldwide compan y
Argentina: see South America
Australia: 3 Figtree Drive, HOMEBUSH, NSW 2140,
Tel. +61 2 9704 8141, Fax. +61 2 9704 8139
Austria: Computerstr. 6, A-1101 WIEN, P.O. Box 213,
Tel. +43 1 60 101 1248, Fax. +43 1 60 101 1210
Belarus: Hotel Minsk Business Center, Bld. 3, r. 1211, Volodarski Str. 6,
220050 MINSK, Tel. +375 172 20 0733, Fax. +375 172 20 0773
Belgium: see The Netherlands
Brazil: seeSouth America
Bulgaria: Philips Bulgaria Ltd., Energoproject, 15thfloor,
51 James Bourchier Blvd., 1407 SOFIA,
Tel. +359 2 68 9211, Fax. +359 2 68 9102
Canada: PHILIPS SEMICONDUCTORS/COMPONENTS,
Tel. +1 800 234 7381, Fax. +1 800 943 0087
China/Hong Kong: 501 Hong Kong Industrial Technology Centre,
72 Tat Chee Avenue, Kowloon Tong, HONG KONG,
Tel. +852 2319 7888, Fax. +852 2319 7700
Colombia: see South America
Czech Republic: see Austria
Denmark: Sydhavnsgade 23, 1780 COPENHAGEN V,
Tel. +45 33 29 3333, Fax. +45 33 29 3905
Finland: Sinikalliontie 3, FIN-02630 ESPOO,
Tel. +358 9 615 800, Fax. +358 9 6158 0920
France: 51 Rue Carnot, BP317, 92156 SURESNES Cedex,
Tel. +33 1 4099 6161, Fax. +33 1 4099 6427
Germany: Hammerbrookstraße 69, D-20097 HAMBURG,
Tel. +49 40 2353 60, Fax. +49 40 2353 6300
Hungary: seeAustria
India: Philips INDIA Ltd, Band Box Building, 2nd floor,
254-D, Dr. Annie Besant Road, Worli, MUMBAI 400 025,
Tel. +91 22 493 8541, Fax. +91 22 493 0966
Indonesia: PTPhilipsDevelopmentCorporation,Semiconductors Division,
Gedung Philips, Jl. Buncit Raya Kav.99-100, JAKARTA 12510,
Tel. +62 21 794 0040 ext. 2501, Fax. +62 21 794 0080
Ireland: Newstead, Clonskeagh, DUBLIN 14,
Tel. +353 1 7640 000, Fax. +353 1 7640 200
Israel: RAPAC Electronics, 7 Kehilat Saloniki St, PO Box 18053,
TEL AVIV 61180, Tel. +972 3 645 0444, Fax. +972 3 649 1007
Italy: PHILIPS SEMICONDUCTORS, Via Casati, 23 - 20052 MONZA (MI),
Tel. +39 039 203 6838, Fax +39 039 203 6800
Japan: Philips Bldg 13-37, Kohnan 2-chome, Minato-ku,
TOKYO 108-8507, Tel. +81 3 3740 5130, Fax. +81 3 3740 5057
Korea: Philips House, 260-199 Itaewon-dong, Yongsan-ku, SEOUL,
Tel. +82 2 709 1412, Fax. +82 2 709 1415
Malaysia: No. 76 Jalan Universiti, 46200 PETALING JAYA, SELANGOR,
Tel. +60 3 750 5214, Fax. +60 3 757 4880
Mexico: 5900 Gateway East, Suite 200, EL PASO, TEXAS 79905,
Tel. +9-5 800 234 7381, Fax +9-5 800 943 0087
Middle East: see Italy
Netherlands: Postbus 90050, 5600 PB EINDHOVEN, Bldg. VB,
Tel. +31 40 27 82785, Fax. +31 40 27 88399
New Zealand: 2 Wagener Place, C.P.O. Box 1041, AUCKLAND,
Tel. +64 9 849 4160, Fax. +64 9 849 7811
Norway: Box 1, Manglerud 0612, OSLO,
Tel. +47 22 74 8000, Fax. +47 22 74 8341
Pakistan: see Singapore
Philippines: Philips Semiconductors Philippines Inc.,
106 Valero St. Salcedo Village, P.O. Box 2108 MCC, MAKATI,
Metro MANILA, Tel. +63 2 816 6380, Fax. +63 2 817 3474
Poland: Al.Jerozolimskie 195 B, 02-222 WARSAW,
Tel. +48 22 5710 000, Fax. +48 22 5710 001
Portugal: see Spain
Romania: see Italy
Russia: Philips Russia, Ul. Usatcheva 35A, 119048 MOSCOW,
Tel. +7 095 755 6918, Fax. +7 095 755 6919
Singapore: Lorong 1, Toa Payoh, SINGAPORE 319762,
Tel. +65 350 2538, Fax. +65 251 6500
Slovakia: see Austria
Slovenia: see Italy
South Africa: S.A. PHILIPS Pty Ltd., 195-215 Main Road Martindale,
2092 JOHANNESBURG, P.O. Box 58088 Newville 2114,
Tel. +27 11 471 5401, Fax. +27 11 471 5398
South America: Al. Vicente Pinzon, 173, 6th floor,
04547-130 SÃO PAULO, SP, Brazil,
Tel. +55 11 821 2333, Fax. +55 11 821 2382
Spain: Balmes 22, 08007 BARCELONA,
Tel. +34 93 301 6312, Fax. +34 93 301 4107
Sweden: Kottbygatan 7, Akalla, S-16485 STOCKHOLM,
Tel. +46 8 5985 2000, Fax. +46 8 5985 2745
Switzerland: Allmendstrasse 140, CH-8027 ZÜRICH,
Tel. +41 1 488 2741 Fax. +41 1 488 3263
Taiwan: Philips Semiconductors, 6F, No. 96, Chien Kuo N. Rd., Sec. 1,
TAIPEI, Taiwan Tel. +886 2 2134 2886, Fax. +886 2 2134 2874
Thailand: PHILIPS ELECTRONICS (THAILAND) Ltd.,
209/2 Sanpavuth-Bangna Road Prakanong, BANGKOK 10260,
Tel. +66 2 745 4090, Fax. +66 2 398 0793
Turkey: Yukari Dudullu, Org. San. Blg., 2.Cad. Nr. 28 81260 Umraniye,
ISTANBUL, Tel. +90 216 522 1500, Fax. +90 216 522 1813
Ukraine: PHILIPS UKRAINE, 4 Patrice Lumumba str., Building B, Floor 7,
252042 KIEV, Tel. +380 44 264 2776, Fax. +380 44 268 0461
United Kingdom: Philips Semiconductors Ltd., 276 Bath Road, Hayes,
MIDDLESEX UB3 5BX, Tel. +44 208 730 5000, Fax. +44 208 754 8421
United States: 811 East Arques Avenue, SUNNYVALE, CA 94088-3409,
Tel. +1 800 234 7381, Fax. +1 800 943 0087
Uruguay: see South America
Vietnam: see Singapore
Yugoslavia: PHILIPS, Trg N. Pasica 5/v, 11000 BEOGRAD,
Tel. +381 11 62 5344, Fax.+381 11 63 5777
For all other countries apply to: Philips Semiconductors,
International Marketing & Sales Communications, Building BE-p, P.O. Box 218,
5600 MD EINDHOVEN, The Netherlands, Fax. +31 40 27 24825
© Philips Electronics N.V. SCA
All rights are reserved. Reproduction in whole or in part is prohibited without the prior written consent of the copyright owner.
The information presented in this document does not form part of any quotation or contract, is believed to be accurate and reliable and may be changed
without notice. No liability will be accepted by the publisher for any consequence of its use. Publication thereof does not convey nor imply any license
under patent- or other industrial or intellectual property rights.
1999
Internet: http://www.semiconductors.philips.com
68
Printed in The Netherlands 285002/01/pp16 Date of release: 1999 Sep 27 Document order number: 9397 750 05732
 Loading...