

Page 1
INTEGRATED CIRCUITS
DATA SH EET
TDA5142T
Brushless DC motor drive circuit
Product specification
Supersedes data of March 1992
File under Integrated Circuits, IC11
Philips Semiconductors
June 1994
Page 2
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
FEATURES
• Full-wave commutation without position sensors
• Built-in start-up circuitry
• Six outputs that can drive three external transistor pairs:
APPLICATIONS
• High-power applications e.g.:
– high-end hard disk drives
– automotive.
– output current 0.2 A (typ.)
– low saturation voltage
– built-in current limiter
GENERAL DESCRIPTION
The TDA5142T is a bipolar integrated circuit used to drive
3-phase brushless DC motors in full-wave mode. The
• Thermal protection
• Tacho output without extra sensor
device is sensorless (saving of 3 hall-sensors) using the
back-EMF sensing technique to sense the rotor position.
It includes a brake function and 6 pre-drivers able to
• Transconductance amplifier for an external
control transistor
• Motor brake facility.
control FETs or bipolar external transistors. It is ideally
suited for high-power applications such as high-end hard
disk drives, automotive and other applications.
QUICK REFERENCE DATA
Measured over full voltage and temperature range.
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
V
P
V
VMOT
supply voltage note 1 4 − 18 V
input voltage to the output
3 − 18 V
driver stages
V
O
I
LIM
driver output voltage IO= 100 mA; lower transistor −−0.35 V
= 100 mA; upper transistor 1.05 −−V
I
O
current limiting V
= 14.5 V; RO=47Ω 150 200 250 mA
VMOT
Note
1. An unstabilized supply can be used.
ORDERING INFORMATION
PACKAGE
TYPE NUMBER
PINS PIN POSITION MATERIAL CODE
TDA5142T 24 SOL plastic SOT137-1
June 1994 2
Page 3

Philips Semiconductors Product specification
BBB
BBBB
BB
BBB
BB
B
B
BB
BB
BB
B
BBBBBBB
B
B
B
B
B
B
Brushless DC motor drive circuit TDA5142T
BLOCK DIAGRAM
BBBBBB
B
B
BBBB
BBBB
BBBB
BBBB
BBBB
BBBB
June 1994 3
Fig.1 Block diagram.
Page 4
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
PINNING
SYMBOL PIN DESCRIPTION
OUT-NB 1 driver output B for driving the n-channel power FET or power NPN
OUT-PB 2 driver output B for driving the n-channel power FET or power PNP
GND1 3 ground (0 V) motor supply return for output stages
OUT-PC 4 driver output C for driving the n-channel power FET or power PNP
OUT-NC 5 driver output C for driving the n-channel power FET or power NPN
VMOT 6 input voltage for the output driver stages
TEST 7 test input/output
BRAKE 8 brake input
FG 9 frequency generator: output of the rotation speed detector stage
GND2 10 ground supply return for control circuits
V
P
CAP-CD 12 external capacitor connection for adaptive communication delay timing
CAP-DC 13 external capacitor connection for adaptive communication delay timing copy
CAP-ST 14 external capacitor connection for start-up oscillator
CAP-TI 15 external capacitor connection for timing
+AMP IN 16 non-inverting input of the transconductance amplifier
−AMP IN 17 inverting input of the transconductance amplifier
AMP OUT 18 transconductance amplifier output (open collector)
COMP-A 19 comparator input corresponding to output A
COMP-B 20 comparator input corresponding to output B
COMP-C 21 comparator input corresponding to output C
MOT0 22 input from the star point of the motor coils
OUT-NA 23 driver output A for driving the n-channel power FET or power NPN
OUT-PA 24 driver output A for driving the n-channel power FET or power PNP
11 supply voltage
June 1994 4
Page 5
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
FUNCTIONAL DESCRIPTION
The TDA5142T offers a sensorless three phase motor
drive function. It is unique in its combination of sensorless
motor drive and full-wave drive. The TDA5142T offers
protected outputs capable of driving external power FETs
or bipolar power transistors. It can easily be adapted for
different motors and applications. The TDA5142T offers
the following features:
• Sensorless commutation by using the motor EMF.
• Built-in start-up circuit.
• Optimum commutation, independent of motor type or
motor loading.
• Six output drivers.
• Maximum output current 0.25 A.
• Outputs protected by current limiting and thermal
protection.
• Low current consumption.
• Accurate frequency generator (FG) by using the
motor EMF.
• Brake function.
• Uncommitted operational transconductance amplifier
(OTA), with a high output current, for use as a control
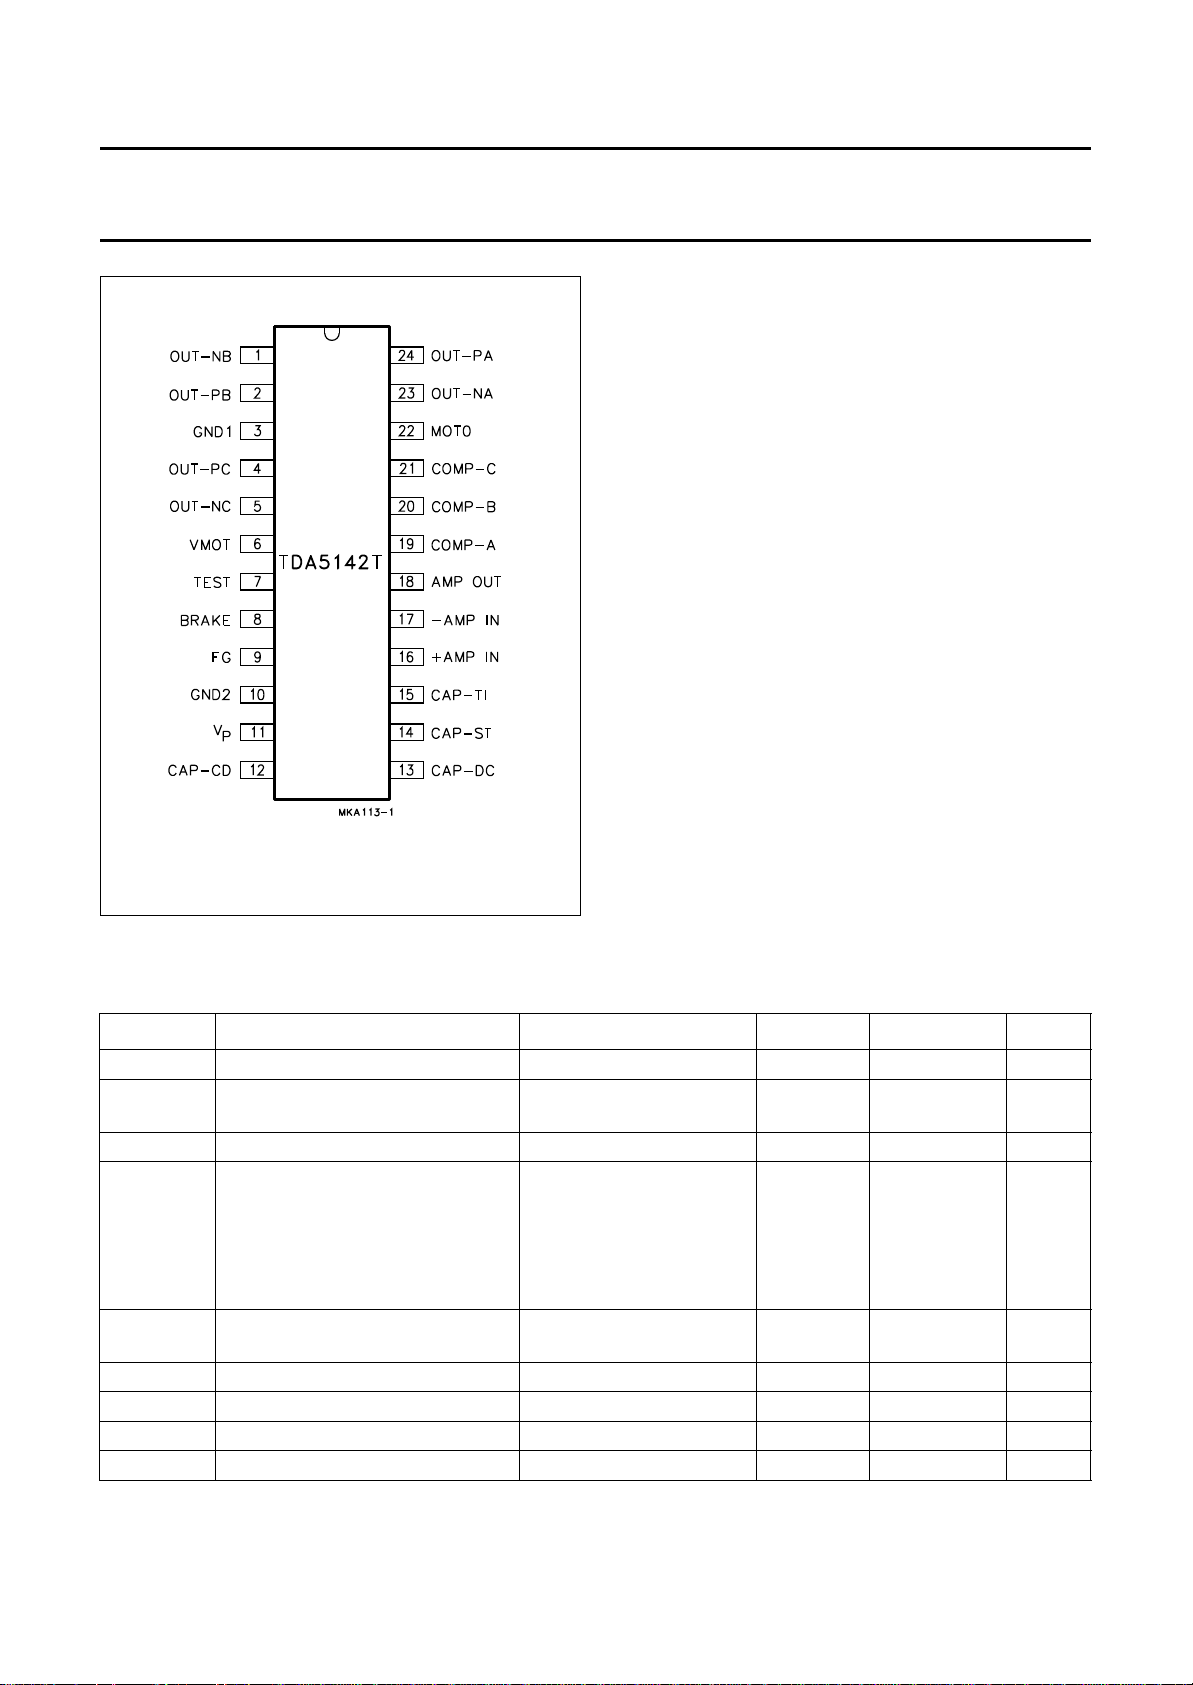
Fig.2 Pin configuration.
amplifier or as a level shifter in a Switched Mode Power
Supply (SMPS) drive.
LIMITING VALUES
In accordance with the Absolute Maximum Rating System (IEC 134).
SYMBOL PARAMETER CONDITIONS MIN. MAX. UNIT
V
P
V
I
supply voltage 4 18 V
input voltage; all pins except
VI< 18 V −0.3 VP + 0.5 V
VMOT
V
VMOT
V
O
VMOT input voltage 3 18 V
output voltage
FG GND V
P
V
AMP OUT − 18 V
OUT-NA, OUT-NB and OUT-NC − V
VMOT
− 0.9 V
OUT-PA, OUT-PB and OUT-PC 0.2 − V
V
I
input voltage CAP-ST, CAP-TI,
− 2.5 V
CAP-CD and CAP-DC
T
stg
T
amb
P
tot
V
es
storage temperature −55 +150 °C
operating ambient temperature 0 +70 °C
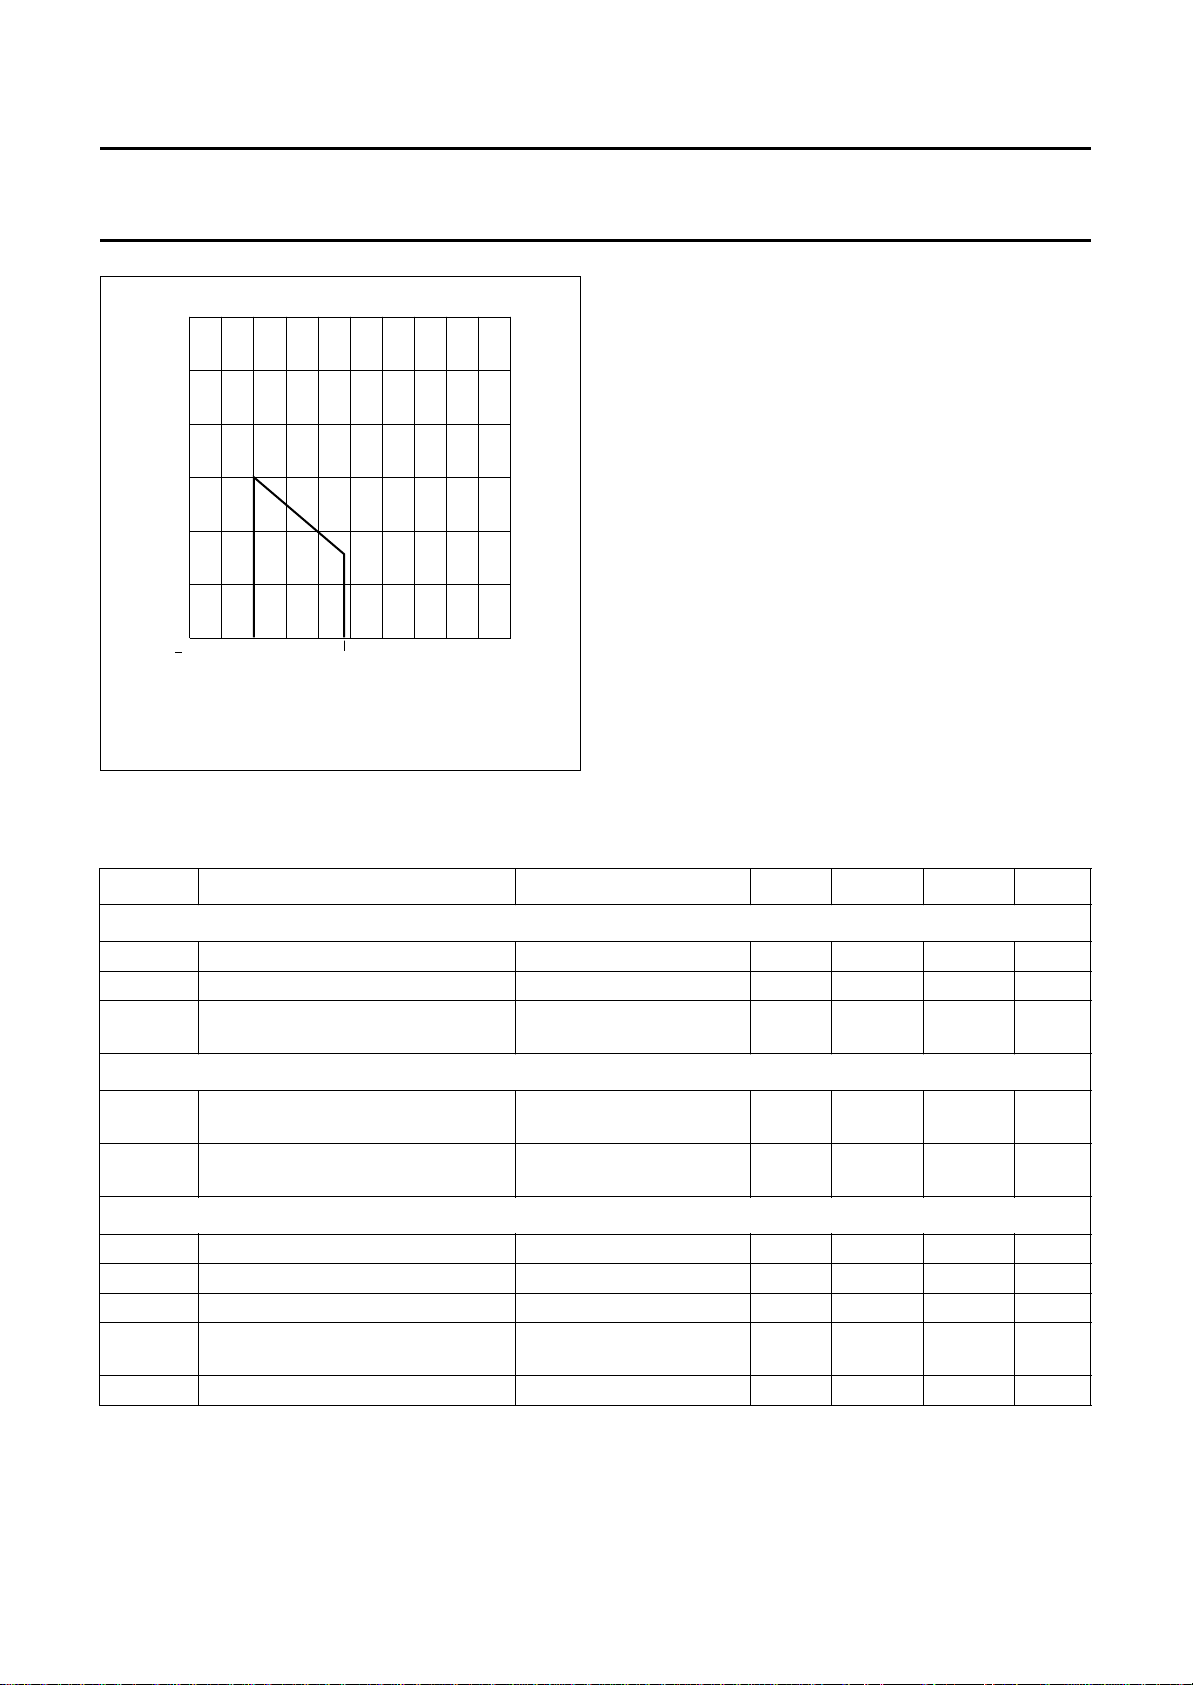
total power dissipation see Fig.3 −− W
electrostatic handling see Chapter “Handling” − 500 V
June 1994 5
Page 6
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
HANDLING
MLB777
o
T ( C)
amb
Every pin withstands the ESD test according to
“MIL-STD-883C class 2”
. Method 3015 (HBM 1500 Ω,
100 pF) 3 pulses + and 3 pulses − on each pin referenced
to ground.
P
(W)
3
tot
2
1
0
50
0 200
50 100 150
70
Fig.3 Power derating curve.
CHARACTERISTICS
V
= 14.5 V; T
P
=25°C; unless otherwise specified.
amb
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
Supply
V
P
I
P
V
VMOT
supply voltage note 1 4 − 18 V
supply current note 2 − 5.2 6.25 mA
input voltage to the output driver
see Fig.1 3 − 18 V
stages
Thermal protection
T
SD
local temperature at temperature
130 140 150 °C
sensor causing shut-down
∆T reduction in temperature before
after shut-down − T
− 30 − K
SD
switch-on
COMP-A, COMP-B, COMP-C and MOT0
V
I
I
V
∆V
I
CSW
CSW
input voltage −0.5 − V
input bias current 0.5 V < VI< V
− 1.5 V −10 − 0 µA
VMOT
VMOT
V
comparator switching level note 3 ±20 ±25 ±30 mV
variation in comparator switching
−3 0 +3 mV
levels
V
hys
comparator input hysteresis − 75 −µV
June 1994 6
Page 7
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
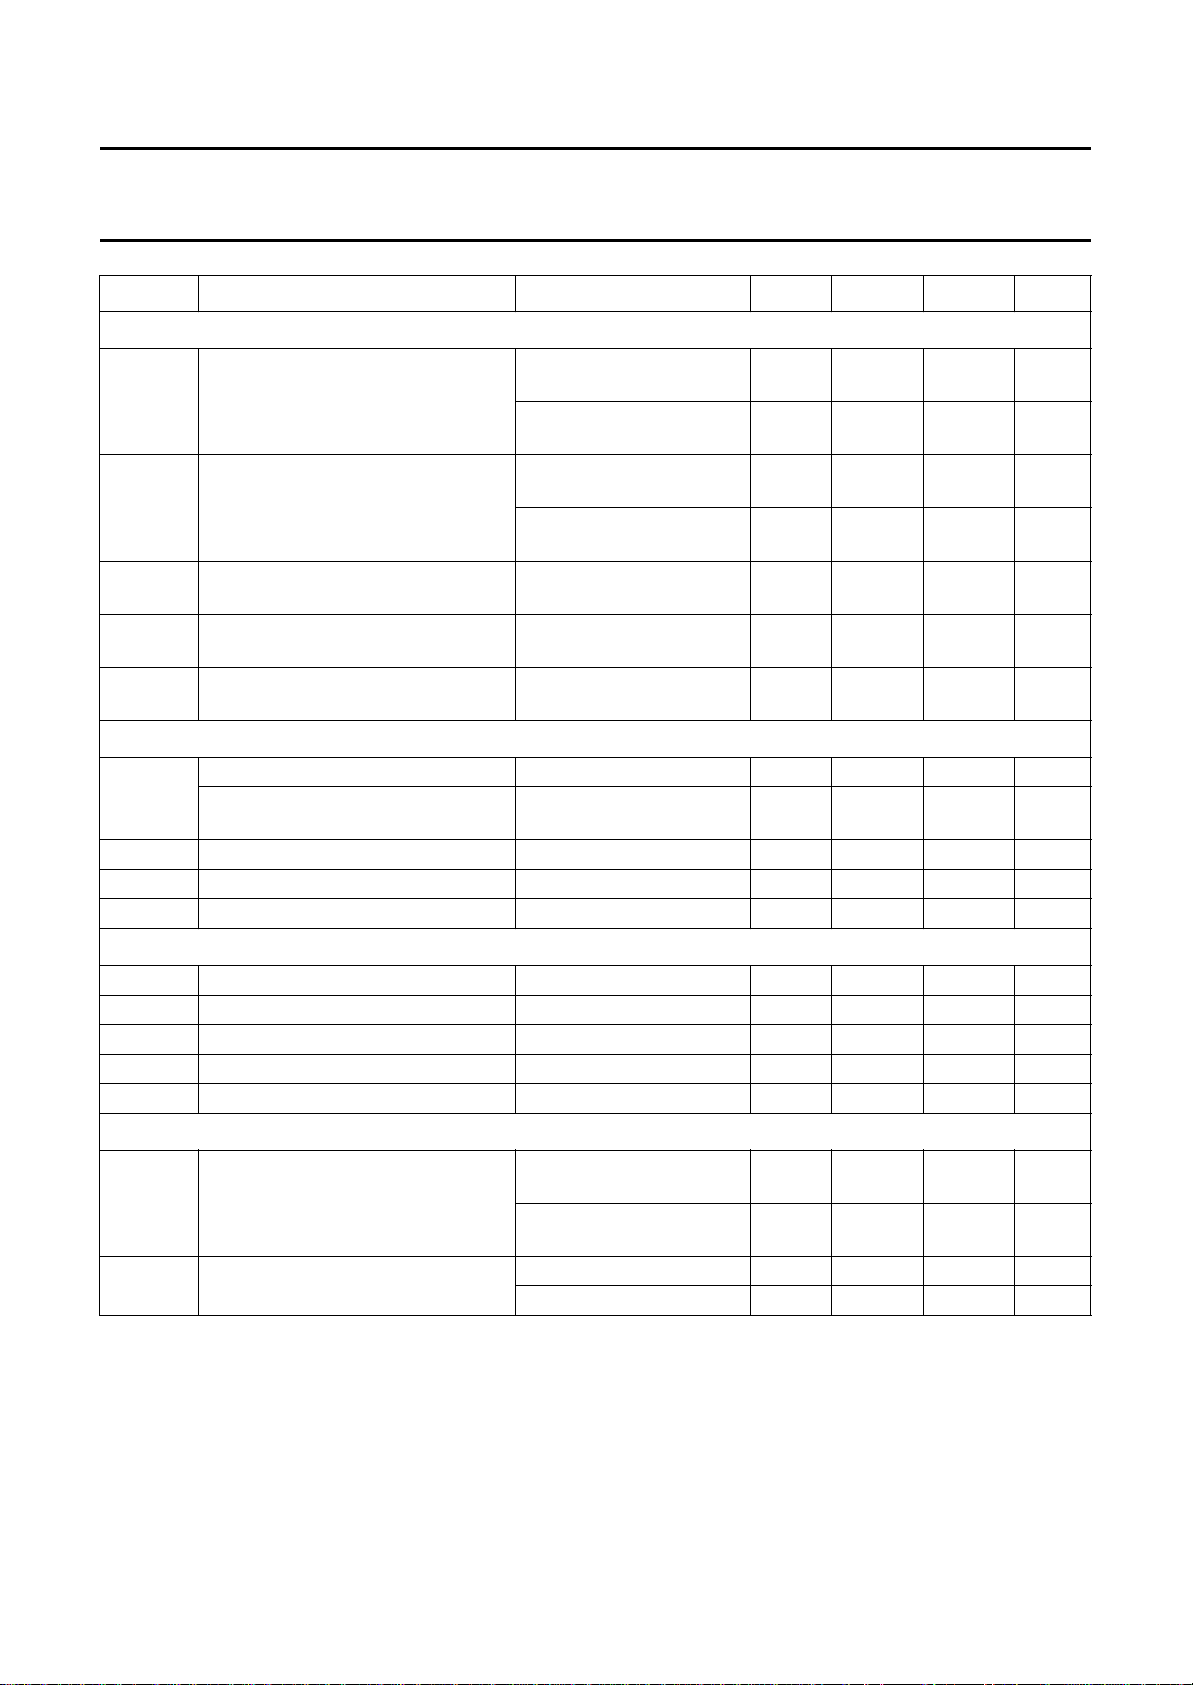
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
OUT-NA, OUT-NB, OUT-NC, OUT-PA, OUT-PB and OUT-PC
V
V
∆V
∆V
I
LIM
O-n
O-p
OL
OH
n-channel driver output voltage upper transistor;
IO= −100 mA
lower transistor;
=10mA
I
O
p-channel driver output voltage upper transistor;
IO= −10 mA
lower transistor;
= 100 mA
I
O
variation in saturation voltage
IO= 100 mA −− 180 mV
between lower transistors
variation in saturation voltage
IO= −100 mA −− 180 mV
between upper transistors
current limiting V
VMOT
= 14.5 V;
RO=47Ω
−1.05 −−V
−− 0.35 V
−1.05 −−V
−− 0.35 V
150 200 250 mA
+AMP IN and −AMP IN
V
I
input voltage −0.3 − VP− 1.7 V
differential mode voltage without
‘latch-up’
I
b
C
I
V
offset
input bias current −− 650 nA
input capacitance − 4 − pF
input offset voltage −− 10 mV
AMP OUT (open collector)
I
V
V
sink
sat
O
output sink current 40 −−mA
saturation voltage II=40mA − 1.5 2.1 V
output voltage −0.5 − +18 V
SR slew rate R
G
tr
transfer gain 0.3 −−S
BRAKE
V
BM
I
I
brake-mode voltage enable brake mode;
input current brake mode −−20 −30 µA
−− ±V
= 330 Ω; CL=50pF 40 −−mA/µs
L
P
V
− 2.3 V
4V<VP<18V
normal mode;
4V<V
<18V
P
2.7 − V
normal mode − 020µA
June 1994 7
Page 8
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
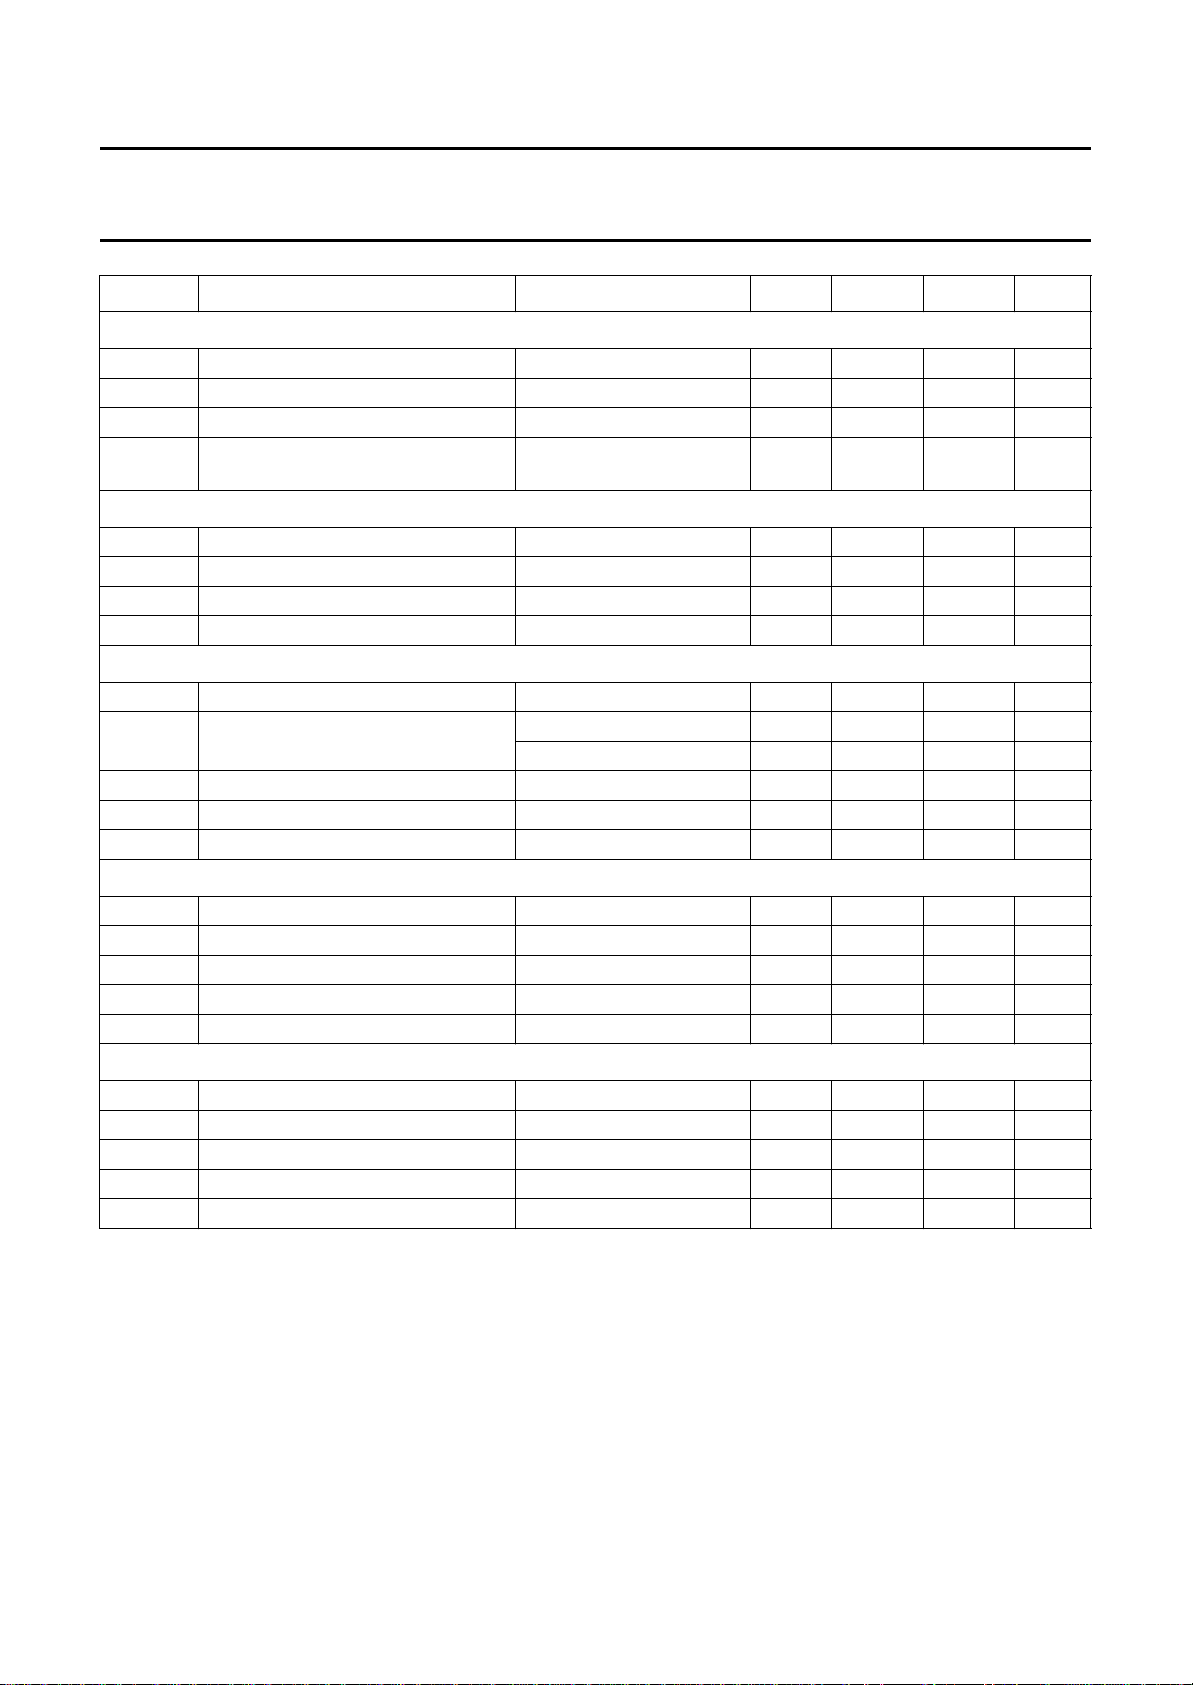
SYMBOL PARAMETER CONDITIONS MIN. TYP. MAX. UNIT
FG (push-pull)
V
OL
V
OH
t
THL
CAP-ST
I
sink
I
source
V
SWL
V
SWH
CAP-TI
I
sink
I
source
V
SWL
V
SWM
V
SWH
CAP-CD
I
sink
I
source
I
sink/Isource
V
IL
V
IH
CAP-DC
I
sink
I
source
I
sink/Isource
V
IL
V
IH
Notes
1. An unstabilized supply can be used.
2. V
3. Switching levels with respect to driver outputs OUT-NA, OUT-NB, OUT-NC, OUT-PA, OUT-PB and OUT-PC.
LOW level output voltage IO= 1.6 mA −− 0.4 V
HIGH level output voltage IO= −60 µAV
−0.3 − V
P
HIGH-to-LOW transition time CL= 50 pF; RL=10kΩ− 0.5 −µs
ratio of FG frequency and
− 1 −
commutation frequency
output sink current 1.5 2.0 2.5 µA
output source current −2.5 −2.0 −1.5 µA
LOW level switching voltage − 0.20 − V
HIGH level switching voltage − 2.20 − V
output sink current − 28 −µA
output source current 0.2 V < V
0.3V<V
< 0.3 V −−57 −µA
CAP-TI
< 2.2 V −−5−µA
CAP-TI
LOW level switching voltage − 50 − mV
MIDDLE level switching voltage − 0.30 − V
HIGH level switching voltage − 2.20 − V
output sink current 10.6 16.2 22 µA
output source current −5.3 −8.1 −11 µA
ratio of sink to source current 1.85 2.05 2.25
LOW level input voltage 850 875 900 mV
HIGH level input voltage 2.3 − 2.5 V
output sink current 10.1 15.5 20.9 µA
output source current −20.9 −15.5 −10.1 µA
ratio of sink to source current 0.9 1.025 1.15
LOW level input voltage 850 875 900 mV
HIGH level input voltage 2.3 − 2.5 V
VMOT=VP
, all other inputs at 0 V; all outputs at VP; IO= 0 mA.
June 1994 8
Page 9
Philips Semiconductors Product specification
B
B
Brushless DC motor drive circuit TDA5142T
APPLICATION INFORMATION
BBBBBBBBBBB
BBBBBBBBBBB
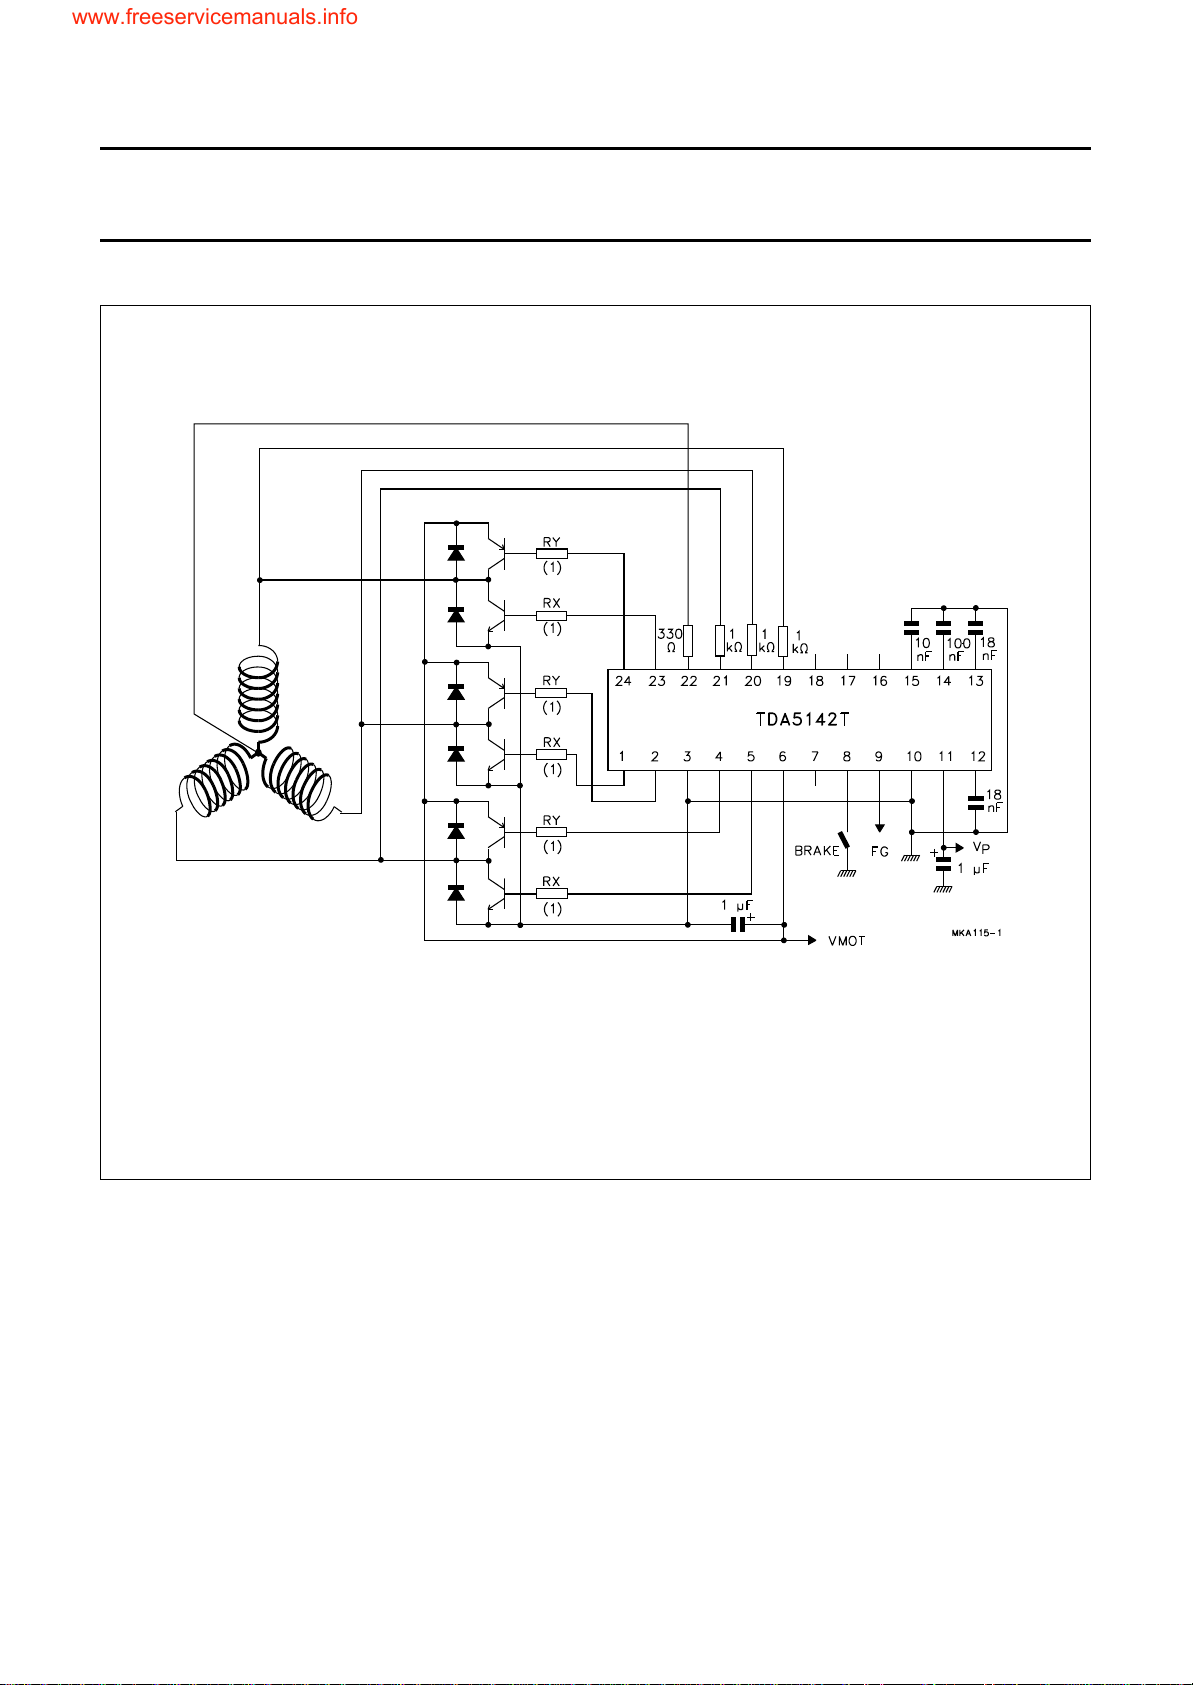
(1) RX = RY > 8 (VMOT − 1.5)
Fig.4 Application diagram without use of the operational transconductance amplifier (OTA) with bipolar
power transistors.
June 1994 9
Page 10
Philips Semiconductors Product specification
B
B
Brushless DC motor drive circuit TDA5142T
BBBBBBBBBBB
BBBBBBBBBBB
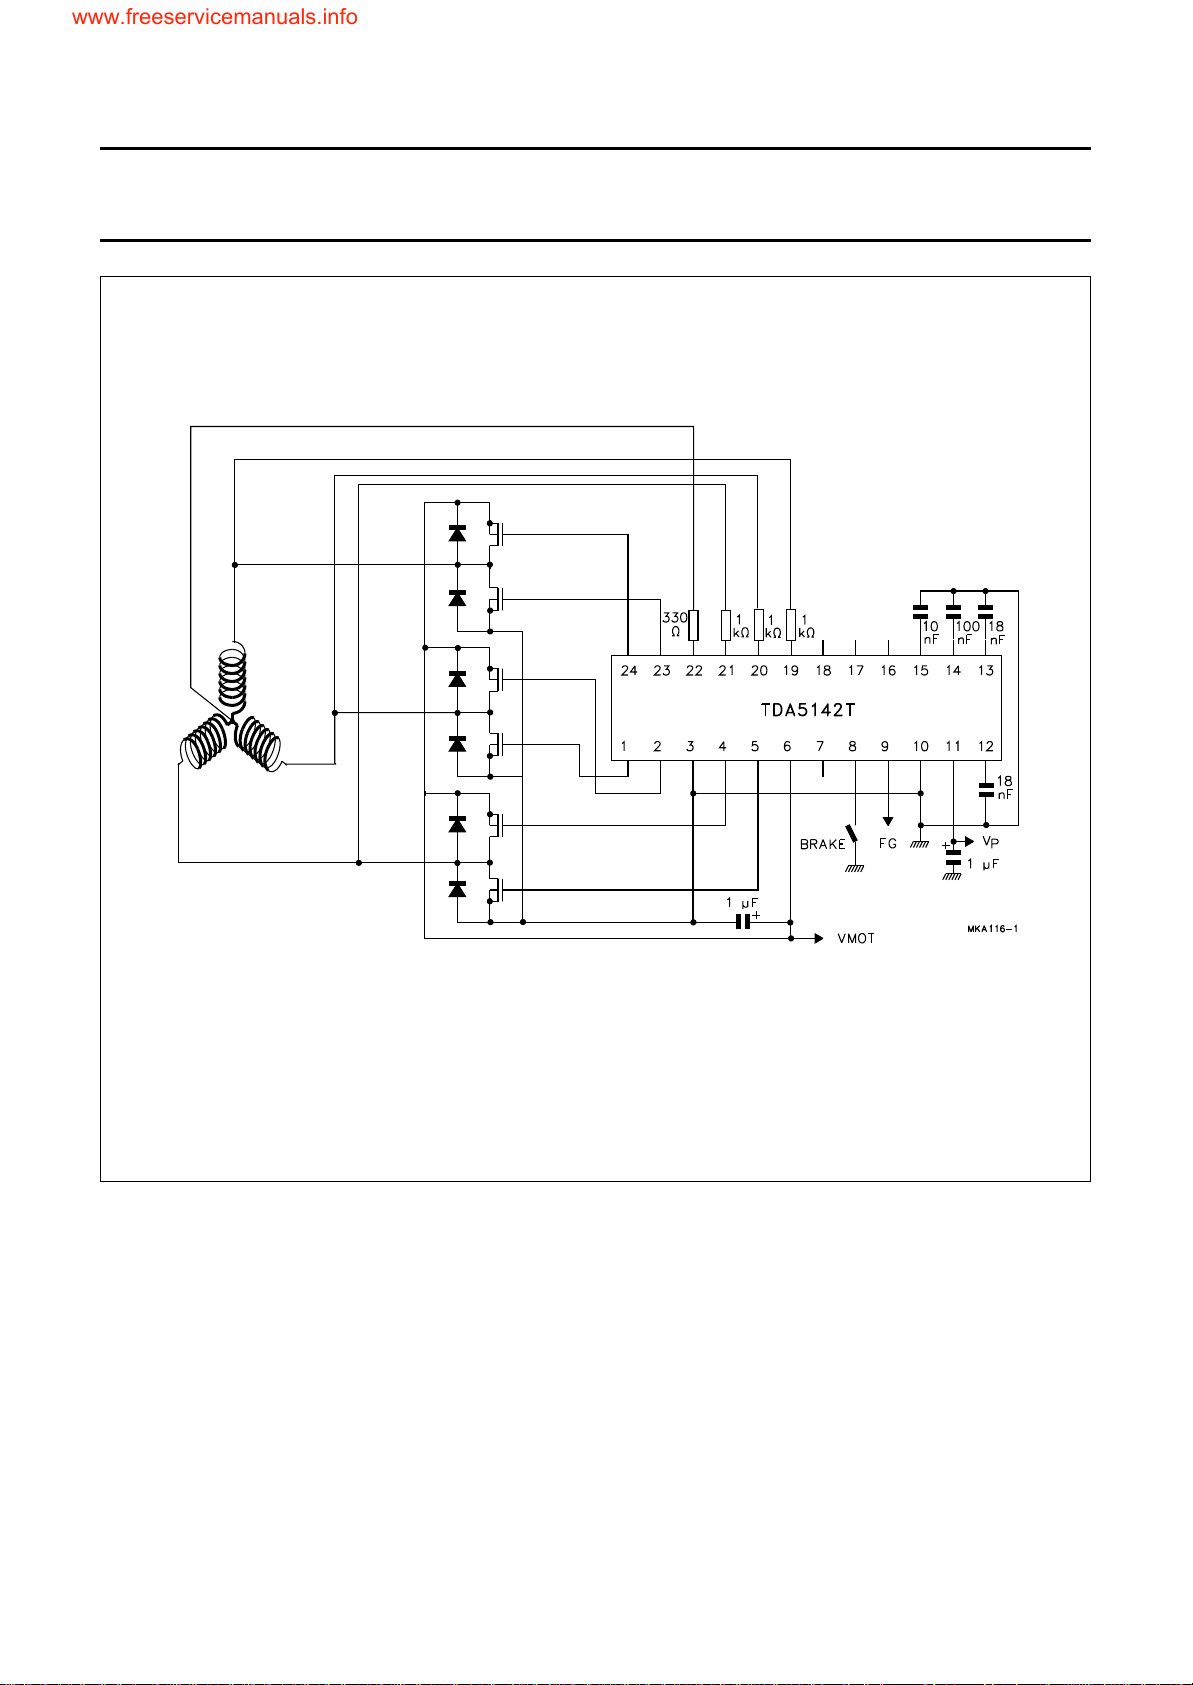
Fig.5 Application diagram without use of the operational transconductance amplifier (OTA)
June 1994 10
with MOSFETs.
Page 11
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
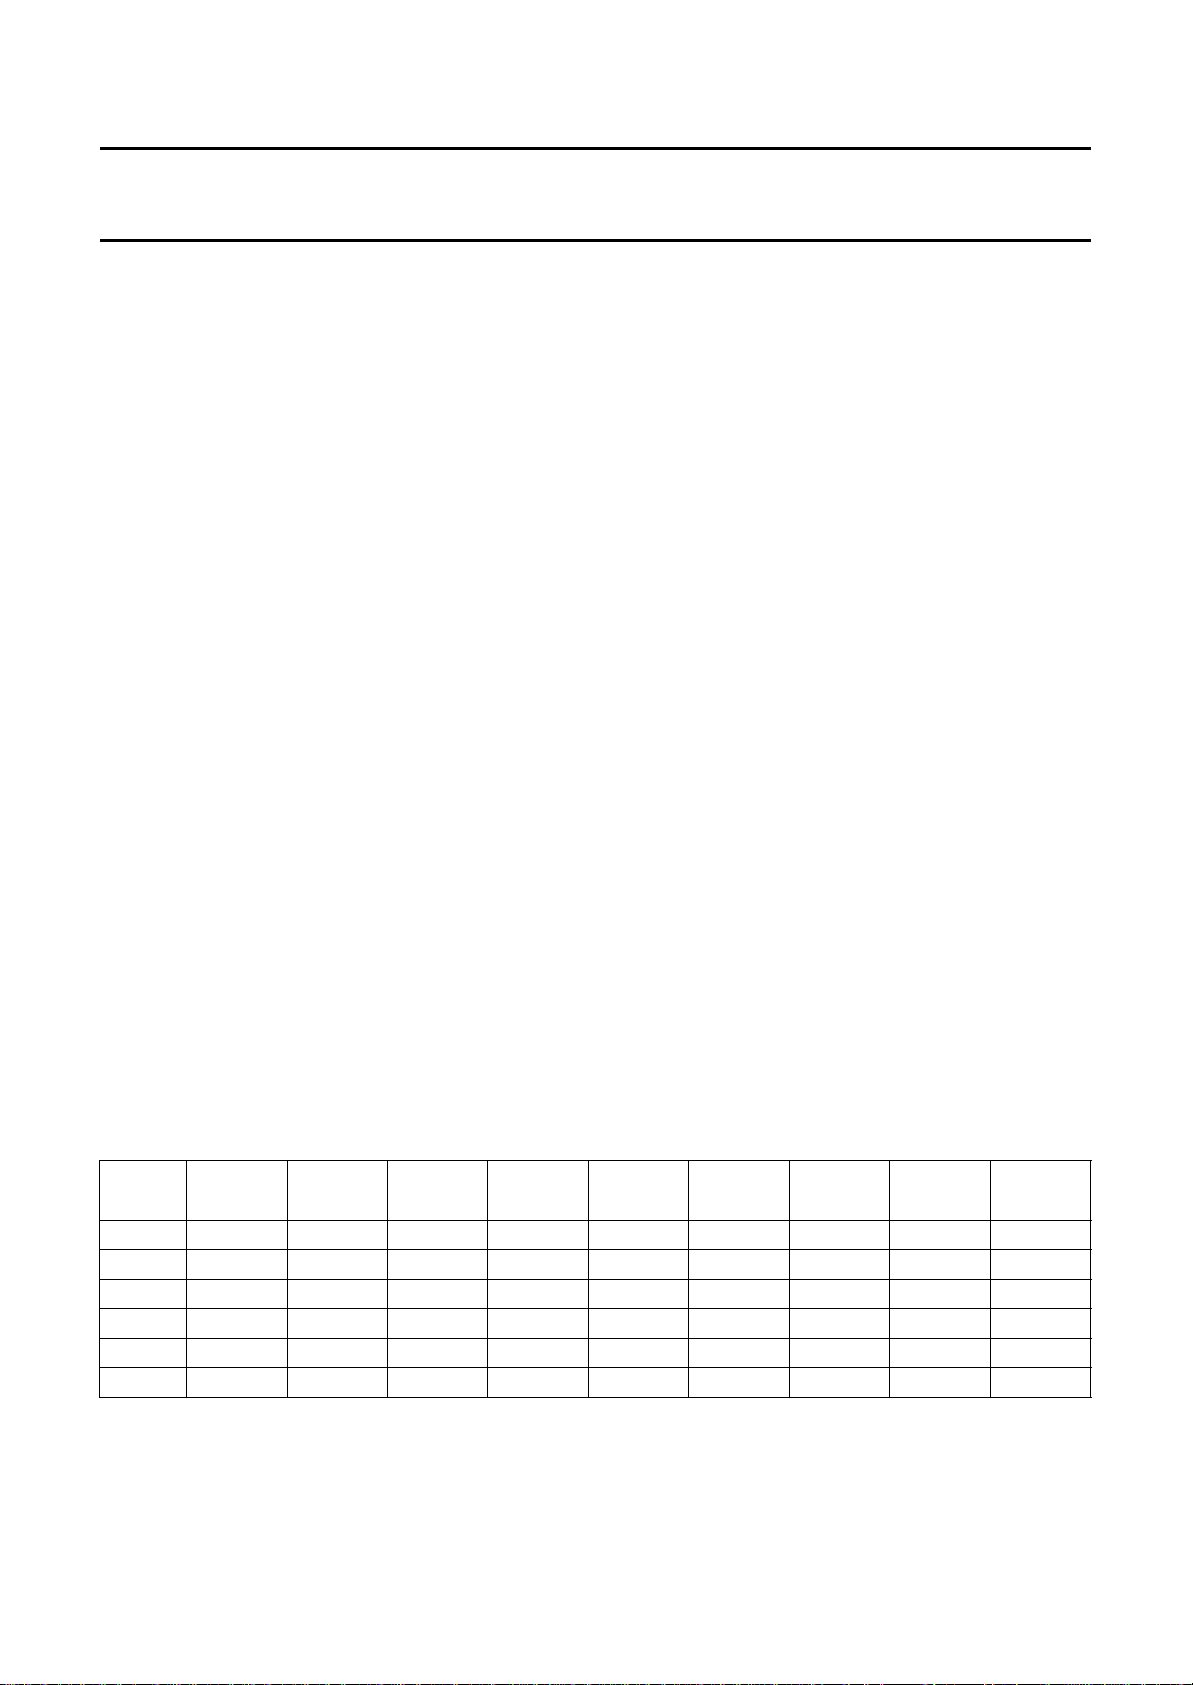
Introduction (see Fig.6)
Full-wave driving of a three phase motor requires three
push-pull output stages. In each of the six possible states
two outputs are active, one sourcing (H) and one sinking
(L). The third output presents a high impedance (Z) to the
motor, which enables measurement of the motor
back-EMF in the corresponding motor coil by the EMF
comparator at each output. The commutation logic is
responsible for control of the output transistors and
selection of the correct EMF comparator. In Table 1 the
sequence of the six possible states of the external
connected output transistors has been depicted and the
corresponding output levels on the NA, PA, NB, PB, NC
and PC outputs of the TDA5142T.
The zero-crossing in the motor EMF (detected by the
comparator selected by the commutation logic) is used to
calculate the correct moment for the next commutation,
that is, the change to the next output state. The delay is
calculated (depending on the motor loading) by the
adaptive commutation delay block.
The output stages are also protected by a current limiting
circuit and by thermal protection.
The detected zero-crossings are used to provide speed
information. The information has been made available on
the FG output pin. This output provides an output signal
with a frequency equal to the commutation frequency.
The system will only function when the EMF voltage from
the motor is present. Therefore, a start oscillator is
provided that will generate commutation pulses when no
zero-crossings in the motor voltage are available.
A timing function is incorporated into the device for internal
timing and for timing of the reverse rotation detection.
The TDA5142T also contains an uncommitted
transconductance amplifier (OTA) that can be used as a
control amplifier. The output is capable of directly driving
an external power transistor.
The TDA5142T is designed for systems with low current
consumption: use of I
2
L logic, adaptive base drive for the
output transistors (patented).
Adjustments
The system has been designed in such a way that the
tolerances of the application components are not critical.
However, the approximate values of the following
components must still be determined:
• The start capacitor; this determines the frequency of the
start oscillator.
• The two capacitors in the adaptive commutation delay
circuit; these are important in determining the optimum
moment for commutation, depending on the type and
loading of the motor.
• The timing capacitor; this provides the system with its
timing signals.
HE START CAPACITOR (CAP-ST)
T
This capacitor determines the frequency of the start
oscillator. It is charged and discharged, with a current of
2 µA, from 0.05 to 2.2 V and back to 0.05 V. The time
taken to complete one cycle is given by:
t
= (2.15 × C) s (with C in µF)
start
The start oscillator is reset by a commutation pulse and so
is only active when the system is in the start-up mode. A
pulse from the start oscillator will cause the outputs to
change to the next state (torque in the motor).
Table 1 Output states.
STATE MOT1
(1)
1ZLHLHHHLL
2HLLLHHZLH
3HLLZLHLHH
4Z L H H L L L H H
5LHHHL LZLH
6LHHZLHHLL
Note
1. H = HIGH state; L = LOW state; Z = high-impedance OFF-state.
June 1994 11
OUT-
(1)
NA
OUT-
(1)
PA
MOT2
(1)
OUT-
(1)
NB
OUT-
(1)
PB
MOT3
(1)
OUT-
(1)
NC
OUT-
(1)
PC
Page 12
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
If the movement of the motor generates enough EMF the
TDA5142T will run the motor. If the amount of EMF
generated is insufficient, then the motor will move one step
only and will oscillate in its new position. The amplitude of
the oscillation must decrease sufficiently before the arrival
of the next start pulse, to prevent the pulse arriving during
the wrong phase of the oscillation. The oscillation of the
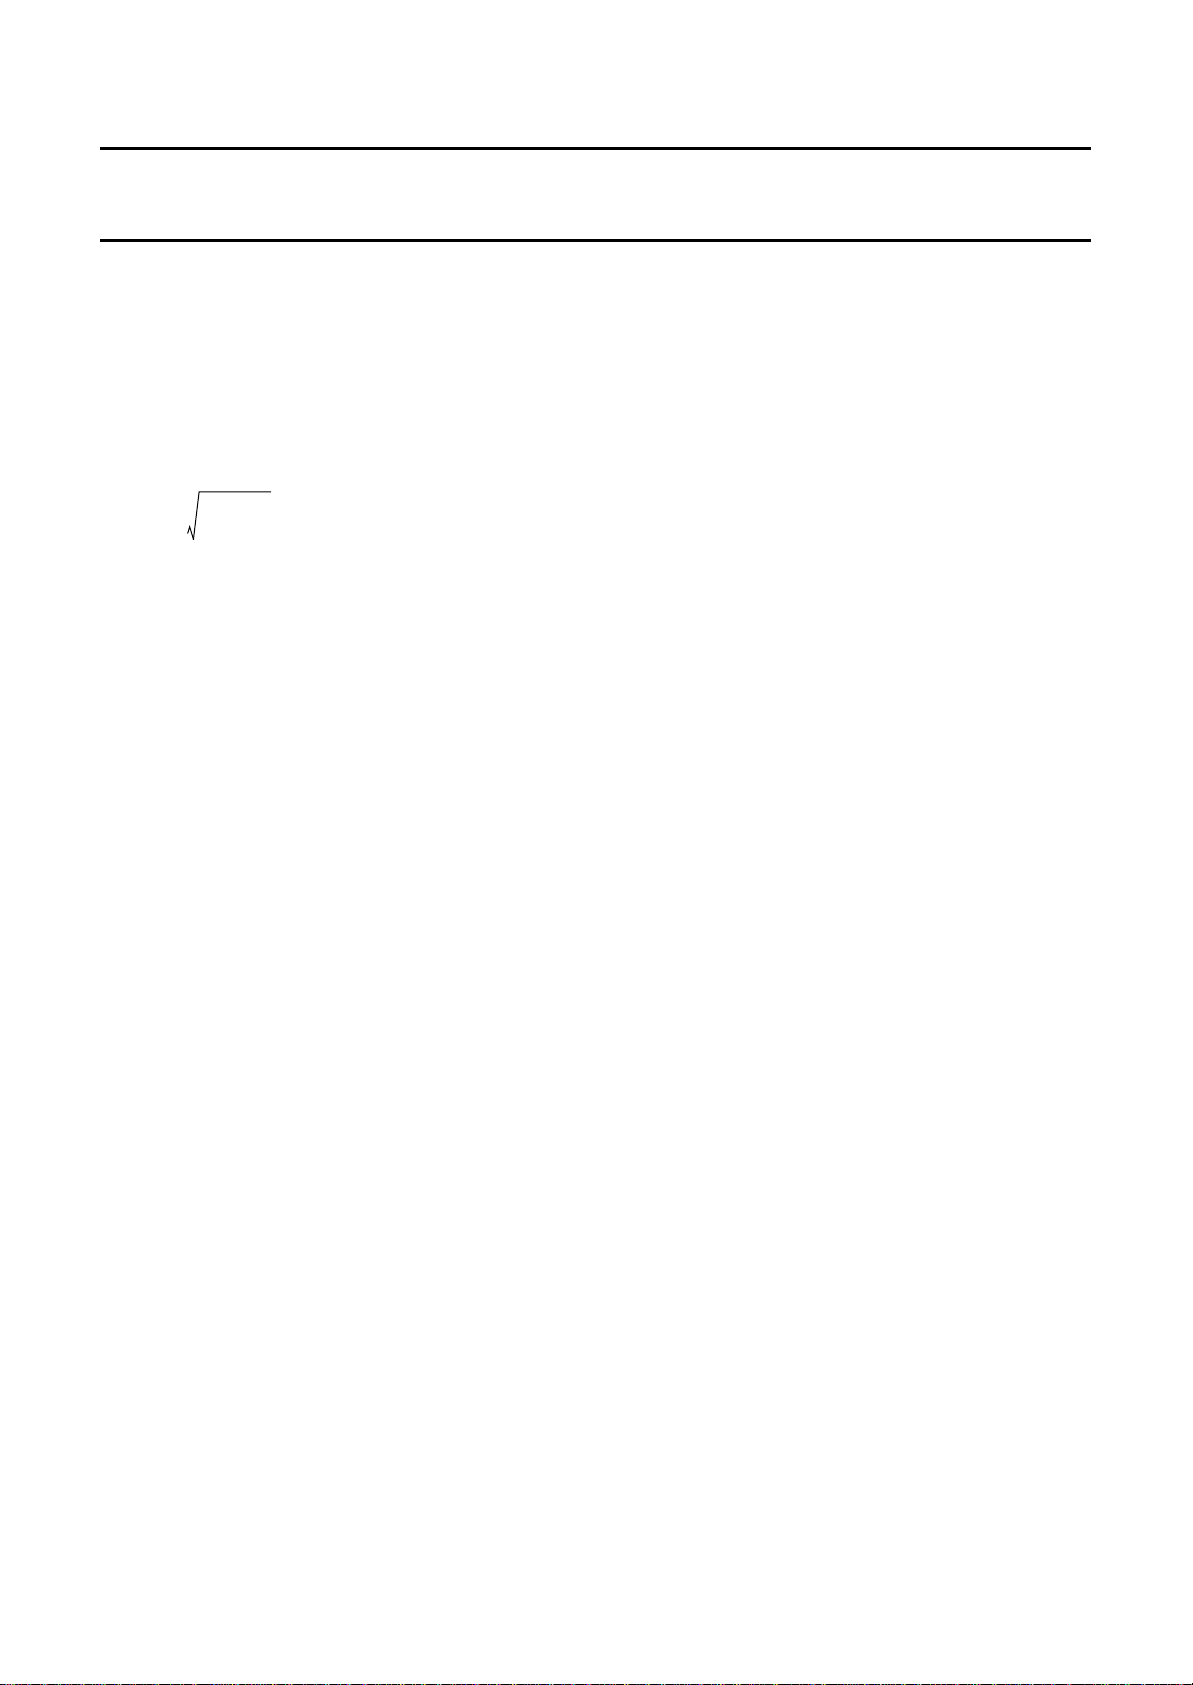
motor is given by:
f
=
osc
where:
= torque constant (N.m/A)
K
t
I = current (A)
p = number of magnetic pole-pairs
J = inertia J (kg.m2).
1
---------------------------------- K
I× p×
t
2π
---------------------- -
J
Example: J = 72 × 10−6kg.m2, K = 25 × 10−3N.m/A,p=6
and I = 0.5 A; this gives f
= 5 Hz. If the damping is high
osc
then a start frequency of 2 Hz can be chosen or
t = 500 ms, thus C = 0.5/2 = 0.25 µF (choose 220 nF).
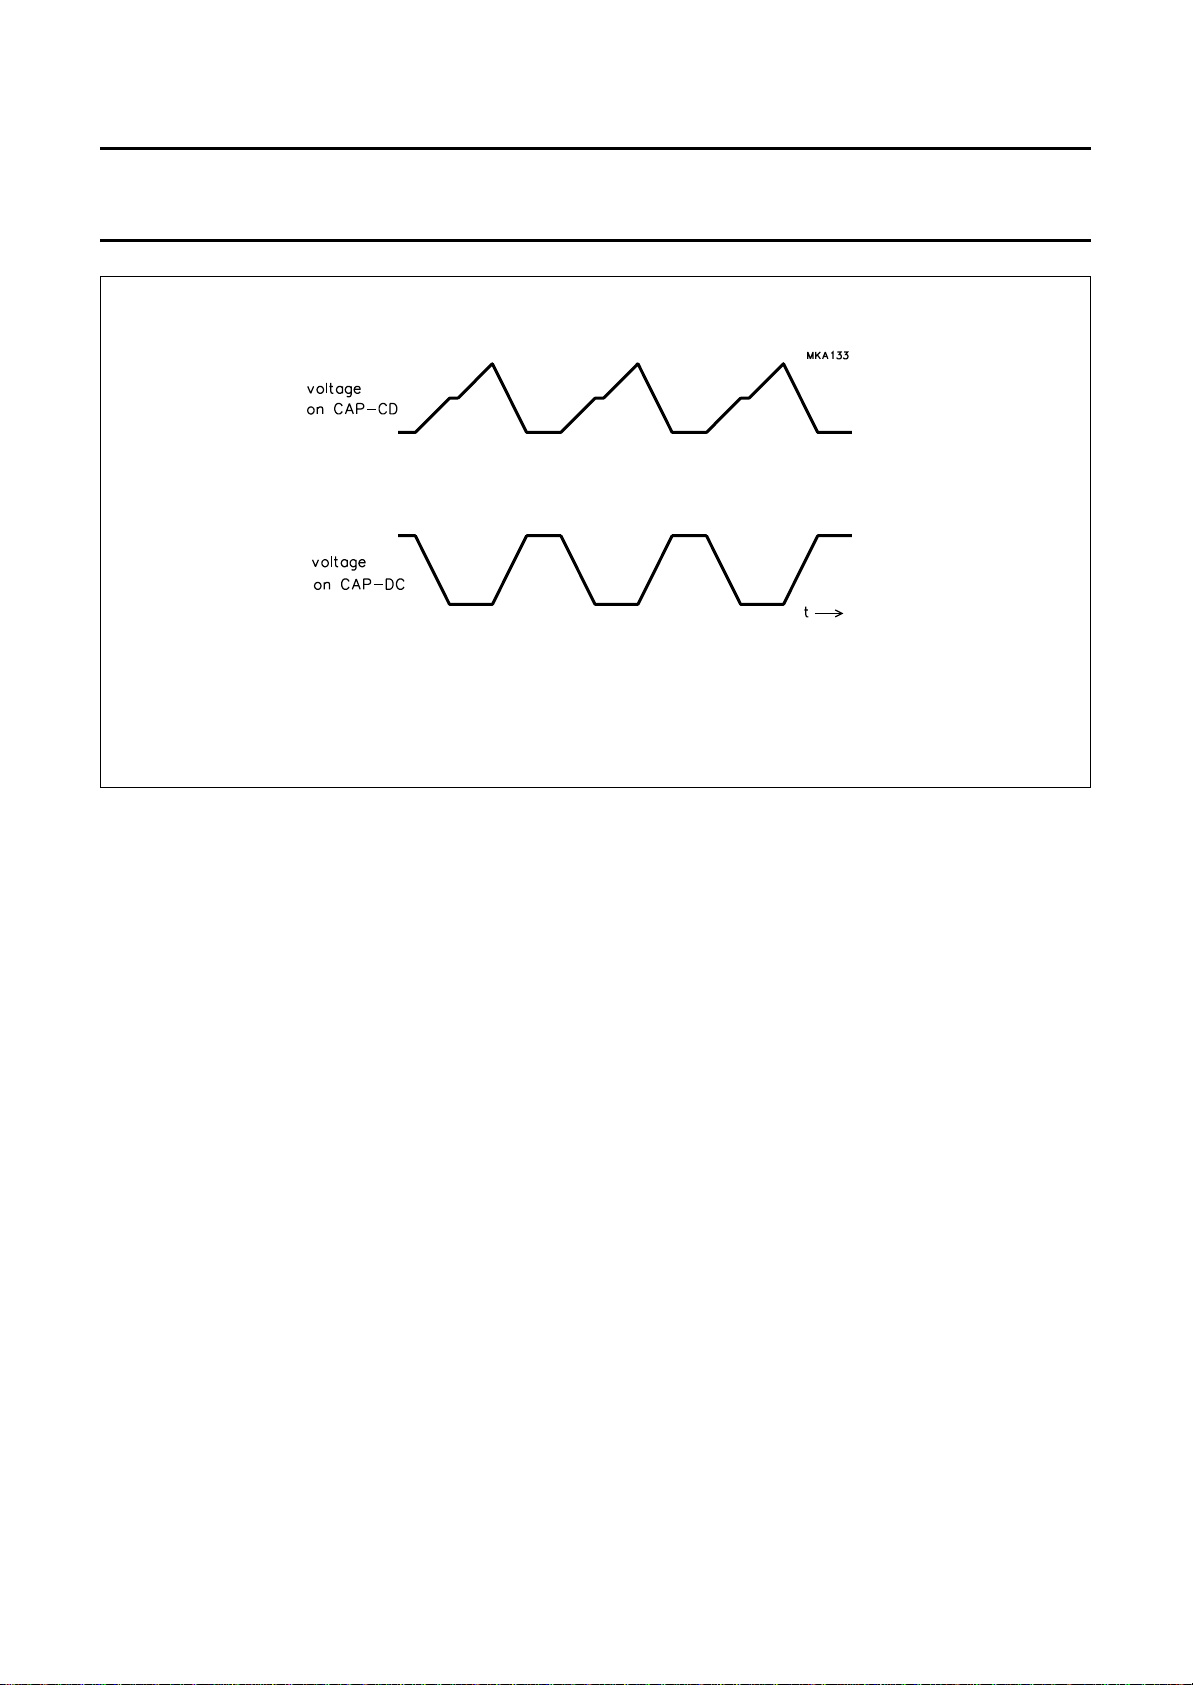
HE ADAPTIVE COMMUTATION DELAY (CAP-CD AND
T
CAP-DC)
In this circuit capacitor CAP-CD is charged during one
commutation period, with an interruption of the charging
current during the diode pulse. During the next
commutation period this capacitor (CAP-CD) is discharged
at twice the charging current. The charging current is
8.1 µA and the discharging current 16.2 µA; the voltage
range is from 0.9 to 2.2 V. The voltage must stay within
this range at the lowest commutation frequency of
interest, f
C
==
:
C1
×
8.1 10
------------------------- f1.3×
6–
6231
(C in nF)
------------ f
C1
If the frequency is lower, then a constant commutation
delay after the zero-crossing is generated by the discharge
from 2.2 to 0.9 V at 20 µA;
maximum delay = (0.076 × C) ms (with C in nF)
Example: nominal commutation frequency = 900 Hz and
the lowest usable frequency = 400 Hz; so:
CAP-CD
6231
------------ 400
The other capacitor, CAP-DC, is used to repeat the same
delay by charging and discharging with 15.5 µA. The same
value can be chosen as for CAP-CD. Figure 7 illustrates
typical voltage waveforms.
June 1994 12
15.6==
(choose 18 nF)
Page 13
Philips Semiconductors Product specification
B
B
BBBBBBBBBBBB
B
B
B
B
B
B
B
B
B
B
B
B
B
B
B
B
BB
B
BB
B
B
B
B
B
B
BB
B
B
BB
B
B
BB
B
B
BB
B
B
Brushless DC motor drive circuit TDA5142T
BBBB
BBBB
B
B
B
B
B
B
B
B
B
B
BBBB
BBBB
BBBBBBBBBBB
BBBBBBBBBBB
B
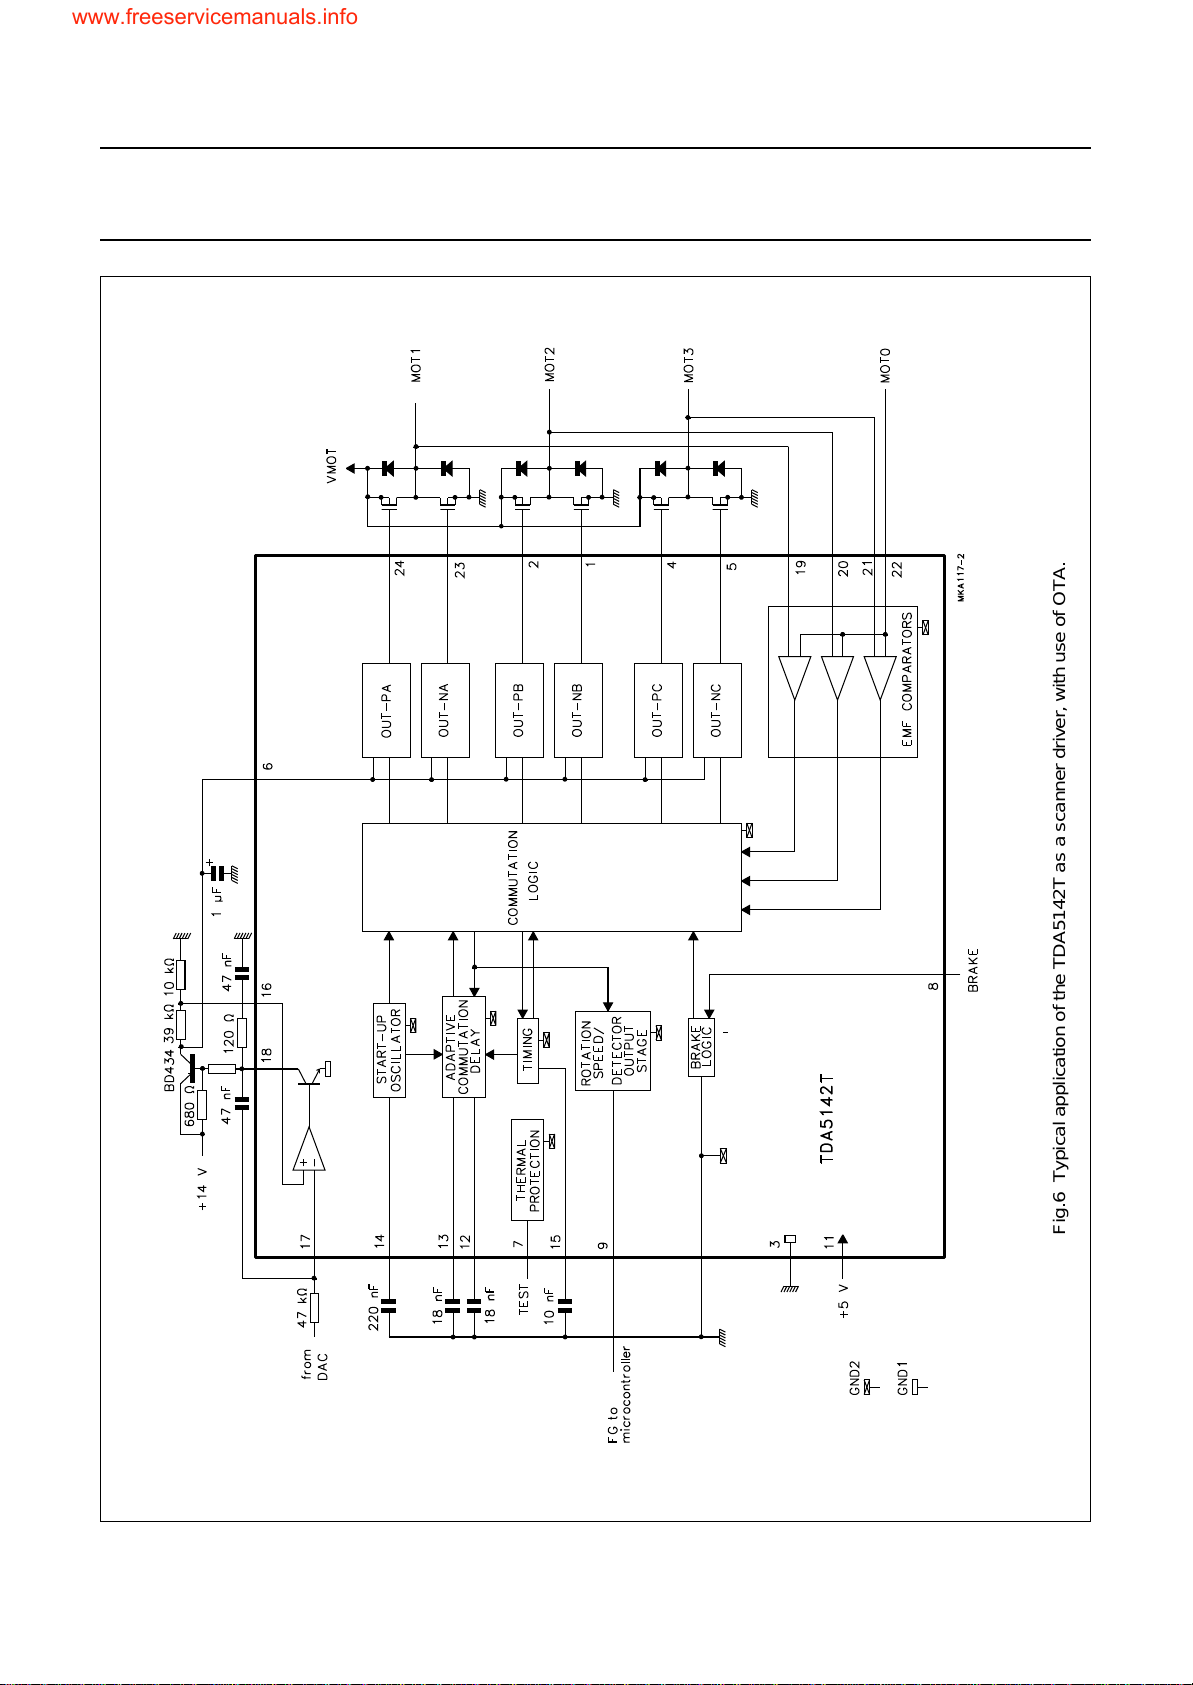
Fig.6 Typical application of the TDA5142T as a scanner driver, with use of OTA.
June 1994 13
Page 14
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
Fig.7 CAP-CD and CAP-DC typical voltage waveforms in normal running mode.
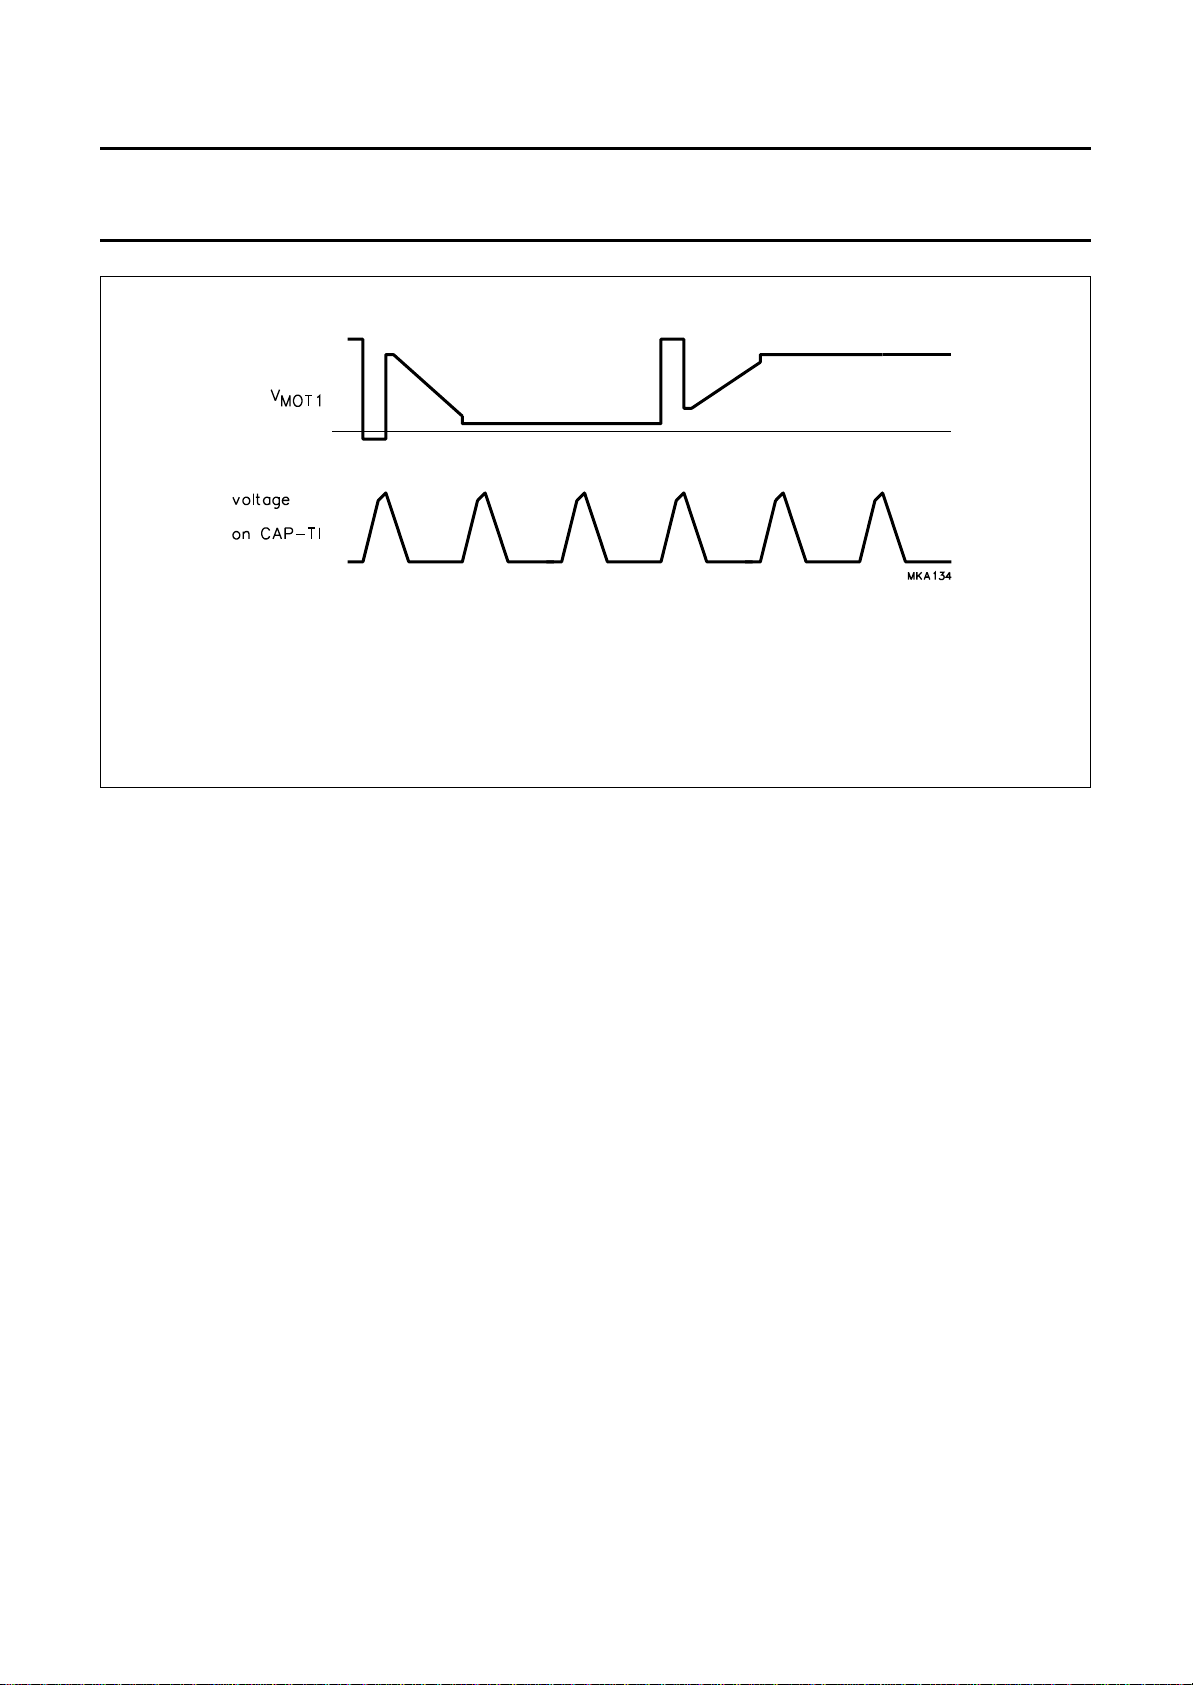
THE TIMING CAPACITOR (CAP-TI)
Capacitor CAP-TI is used for timing the successive steps
within one commutation period; these steps include some
internal delays.
The most important function is the watchdog time in which
the motor EMF has to recover from a negative diode-pulse
back to a positive EMF voltage (or vice versa). A watchdog
timer is a guarding function that only becomes active when
the expected event does not occur within a predetermined
time.
The EMF usually recovers within a short time if the motor
is running normally (<<ms). However, if the motor is
motionless or rotating in the reverse direction, then the
time can be longer (>>ms).
A watchdog time must be chosen so that it is long enough
for a motor without EMF (still) and eddy currents that may
stretch the voltage in a motor winding; however, it must be
short enough to detect reverse rotation. If the watchdog
time is made too long, then the motor may run in the wrong
direction (with little torque).
The capacitor is charged, with a current of 57 µA, from
0.2 to 0.3 V. Above this level it is charged, with a current of
5 µA, up to 2.2 V only if the selected motor EMF remains
in the wrong polarity (watchdog function). At the end, or, if
the motor voltage becomes positive, the capacitor is
discharged with a current of 28 µA. The watchdog time is
the time taken to charge the capacitor, with a current of
5 µA, from 0.3 to 2.2 V.
To ensure that the internal delays are covered CAP-TI
must have a minimum value of 2 nF. For the watchdog
function a value for CAP-TI of 10 nF is recommended.
To ensure a good start-up and commutation, care must be
taken that no oscillations occur at the trailing edge of the
flyback pulse. Snubber networks at the outputs should be
critically damped.
Typical voltage waveforms are illustrated by Fig.8.
June 1994 14
Page 15
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
If the chosen value of CAP-TI is too small oscillations can occur in certain positions of a blocked rotor. If the chosen value is too large, then it
is possible that the motor may run in the reverse direction (synchronously with little torque).
Fig.8 Typical CAP-TI and V
voltage waveforms in normal running mode.
MOT1
Other design aspects
There are other design aspects concerning the application
of the TDA5142T besides the commutation function. They
are:
• Generation of the tacho signal FG
• General purpose operational transconductance
amplifier (OTA)
• Possibilities of motor control
• Brake function
• Reliability.
SIGNAL
FG
The FG signal is generated in the TDA5142T by using the
zero-crossing of the motor EMF from the three motor
windings and the commutation signal.
Output FG switches from HIGH-to-LOW on all zero
crossings and from LOW-to-HIGH on all commutations.
Output FG can source typically 75 µA and sink more
than 3 mA.
Example: a 3-phase motor with 6 magnetic pole-pairs at
1500 rpm and with a full-wave drive has a commutation
frequency of 25 × 6 × 6 = 900 Hz, and generates a tacho
signal of 900 Hz.
HE OPERATIONAL TRANSCONDUCTANCE AMPLIFIER (OTA)
T
The OTA is an uncommitted amplifier with a high output
current (40 mA) that can be used as a control amplifier.
The common mode input range includes ground (GND)
and rises to VP− 1.7 V. The high sink current enables the
OTA to drive a power transistor directly in an analog
control amplifier.
Although the gain is not extremely high (0.3 S), care must
be taken with the stability of the circuit if the OTA is used
as a linear amplifier as no frequency compensation has
been provided.
The convention for the inputs (inverting or not) is the same
as for a normal operational amplifier: with a resistor (as
load) connected from the output (AMP OUT) to the positive
supply, a positive-going voltage is found when the
non-inverting input (+AMP IN) is positive with respect to
the inverting input (−AMP IN). Confusion is possible
because a ‘plus’ input causes less current, and so a
positive voltage.
OTOR CONTROL
M
DC motors can be controlled in an analog manner using
the OTA.
For the analog control an external transistor is required.
The OTA can supply the base current for this transistor
and act as a control amplifier (see Fig.6).
June 1994 15
Page 16
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
BRAKE FUNCTION
• If the voltage on pin 8 is <2.3 V the motor brakes; in this
condition the external outputs are driven to a HIGH
voltage level.
• If pin 8 is floating or the voltage is >2.7 V the motor
runs normally.
R
ELIABILITY
It is necessary to protect high current circuits and the
output stages are protected in two ways:
• Current limiting of the ‘lower’ output transistors. The
‘upper’ output transistors use the same base current as
the conducting ‘lower’ transistor (+15%). This means
that the current to and from the output stages is limited.
• Thermal protection of the six output transistors is
achieved in such a way that the transistors are switched
off when the local temperature becomes too high.
June 1994 16
Page 17
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
PACKAGE OUTLINE
handbook, full pagewidth
S
pin 1
index
112
0.9
0.4
(4x)
15.6
15.2
1.27
0.49
0.36
0.1 S
1324
0.25 M
(24x)
2.45
2.25
0.3
0.1
10.65
10.00
detail A
7.6
7.4
1.1
0.5
1.1
1.0
0.32
0.23
o
0 to 8
MBC235 - 1
A
2.65
2.35
Dimensions in mm.
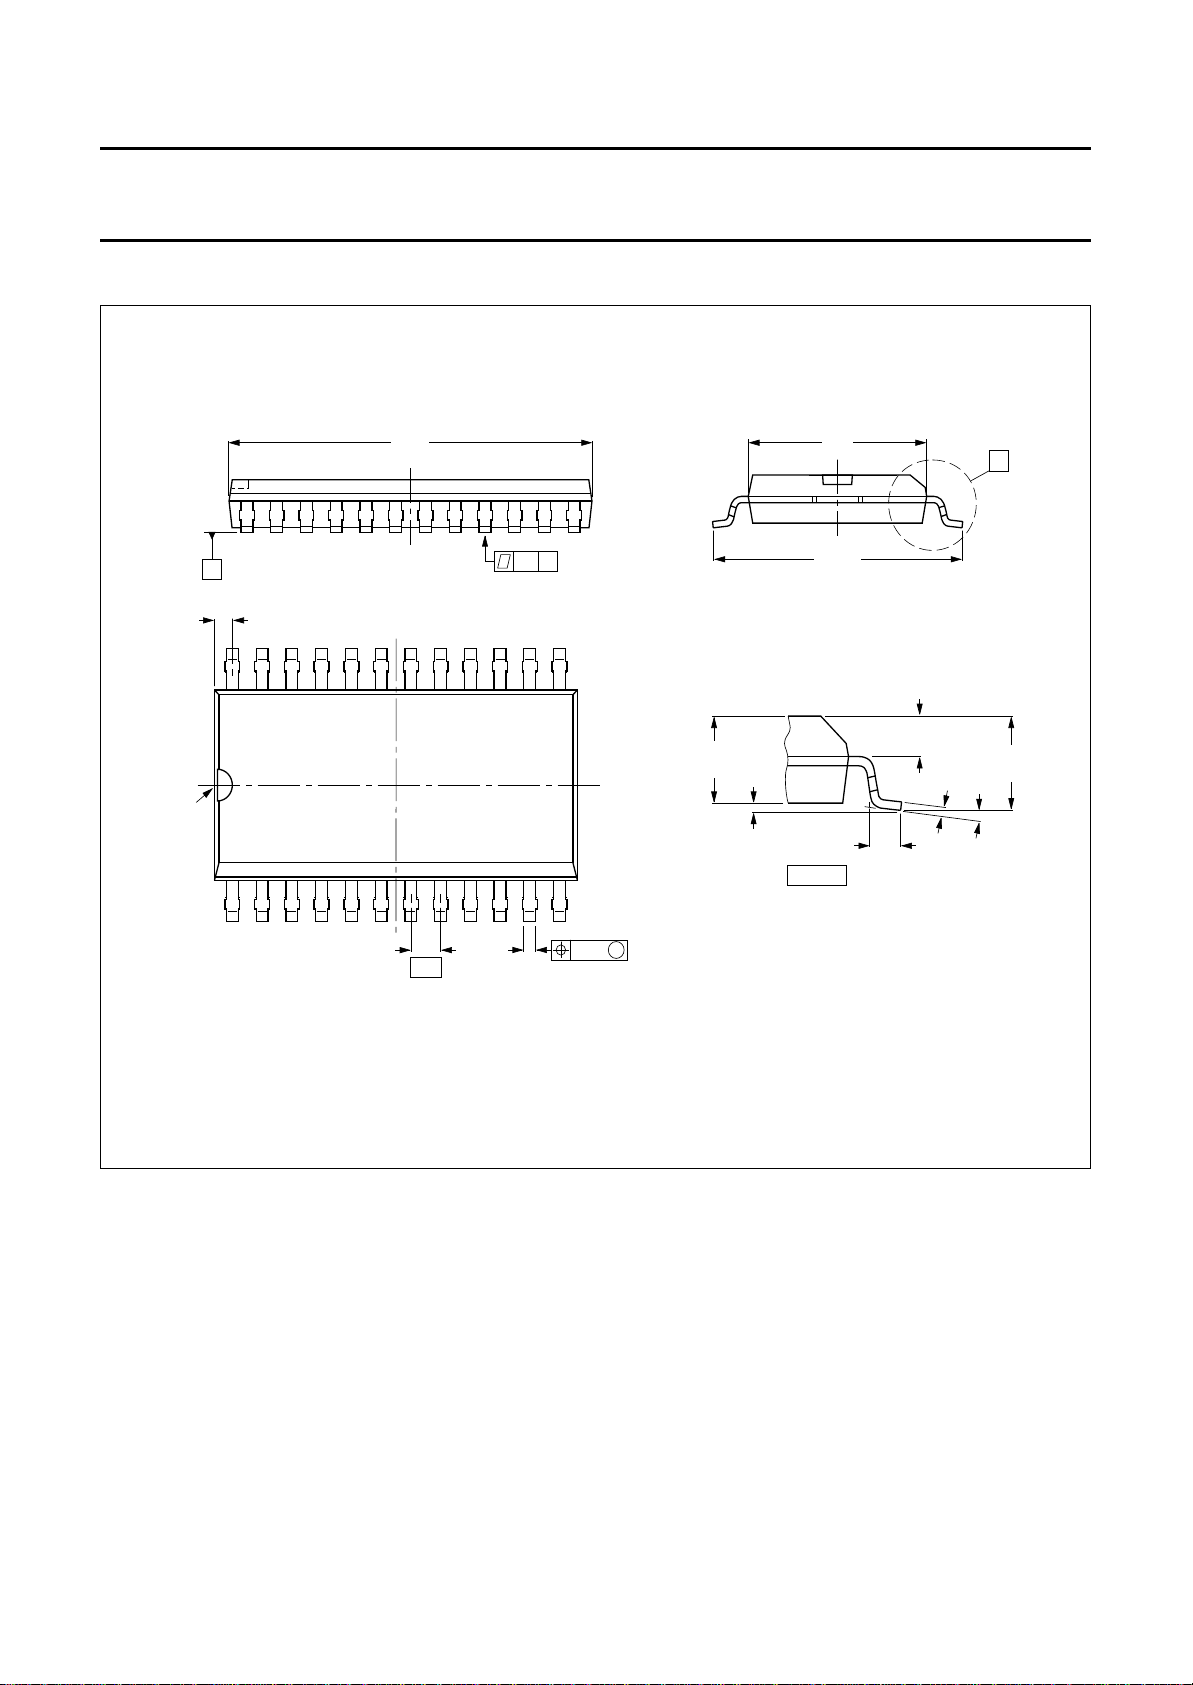
Fig.9 Plastic small outline package; 24 leads; large body (SOT137-1; SO24L).
June 1994 17
Page 18
Philips Semiconductors Product specification
Brushless DC motor drive circuit TDA5142T
SOLDERING
Plastic small-outline packages
YWAVE
B
During placement and before soldering, the component
must be fixed with a droplet of adhesive. After curing the
adhesive, the component can be soldered. The adhesive
can be applied by screen printing, pin transfer or syringe
dispensing.
Maximum permissible solder temperature is 260 °C, and
maximum duration of package immersion in solder bath is
10 s, if allowed to cool to less than 150 °C within 6 s.
Typical dwell time is 4 s at 250 °C.
A modified wave soldering technique is recommended
using two solder waves (dual-wave), in which a turbulent
wave with high upward pressure is followed by a smooth
laminar wave. Using a mildly-activated flux eliminates the
need for removal of corrosive residues in most
applications.
Y SOLDER PASTE REFLOW
B
Reflow soldering requires the solder paste (a suspension
of fine solder particles, flux and binding agent) to be
applied to the substrate by screen printing, stencilling or
pressure-syringe dispensing before device placement.
Several techniques exist for reflowing; for example,
thermal conduction by heated belt, infrared, and
vapour-phase reflow. Dwell times vary between 50 and
300 s according to method. Typical reflow temperatures
range from 215 to 250 °C.
Preheating is necessary to dry the paste and evaporate
the binding agent. Preheating duration: 45 min at 45 °C.
EPAIRING SOLDERED JOINTS (BY HAND-HELD SOLDERING
R
IRON OR PULSE
-HEATED SOLDER TOOL)
Fix the component by first soldering two, diagonally
opposite, end pins. Apply the heating tool to the flat part of
the pin only. Contact time must be limited to 10 s at up to
300 °C. When using proper tools, all other pins can be
soldered in one operation within 2 to 5 s at between 270
and 320 °C. (Pulse-heated soldering is not recommended
for SO packages.)
For pulse-heated solder tool (resistance) soldering of VSO
packages, solder is applied to the substrate by dipping or
by an extra thick tin/lead plating before package
placement.
DEFINITIONS
Data sheet status
Objective specification This data sheet contains target or goal specifications for product development.
Preliminary specification This data sheet contains preliminary data; supplementary data may be published later.
Product specification This data sheet contains final product specifications.
Limiting values
Limiting values given are in accordance with the Absolute Maximum Rating System (IEC 134). Stress above one or
more of the limiting values may cause permanent damage to the device. These are stress ratings only and operation
of the device at these or at any other conditions above those given in the Characteristics sections of the specification
is not implied. Exposure to limiting values for extended periods may affect device reliability.
Application information
Where application information is given, it is advisory and does not form part of the specification.
LIFE SUPPORT APPLICATIONS
These products are not designed for use in life support appliances, devices, or systems where malfunction of these
products can reasonably be expected to result in personal injury. Philips customers using or selling these products for
use in such applications do so at their own risk and agree to fully indemnify Philips for any damages resulting from such
improper use or sale.
June 1994 18
 Loading...